cE9s4PsOgeBQIORwjd5!~~60_1-634818020230156250.jpg)
Lupuc4g~~60_35-634706297915000000.jpg)
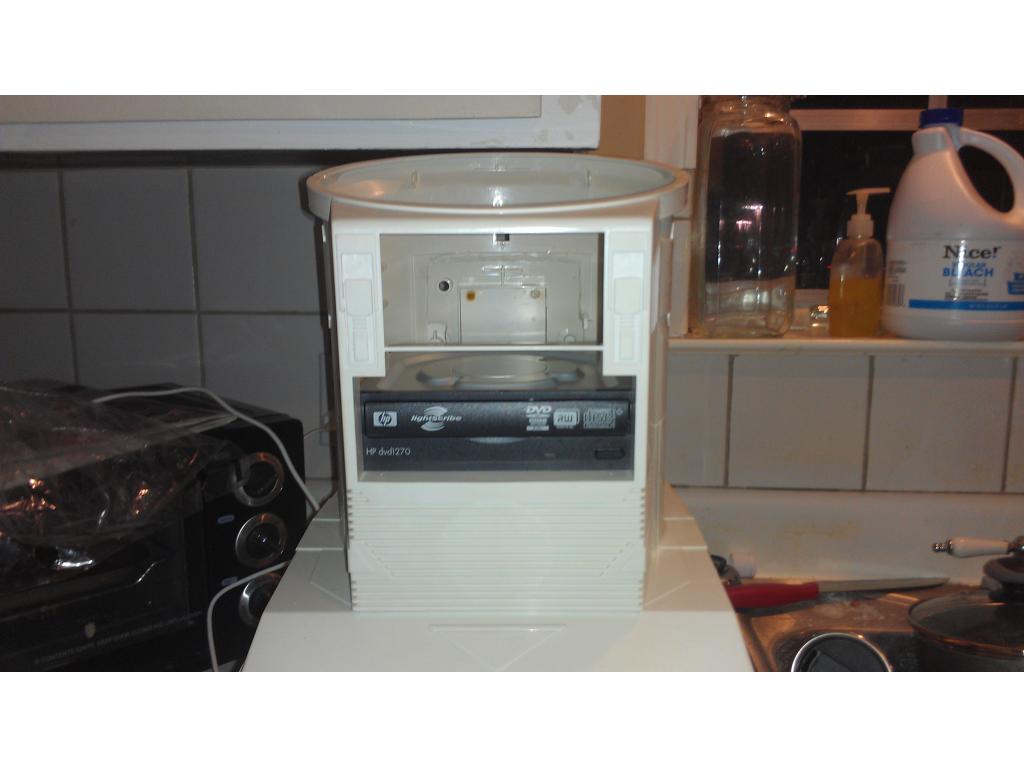
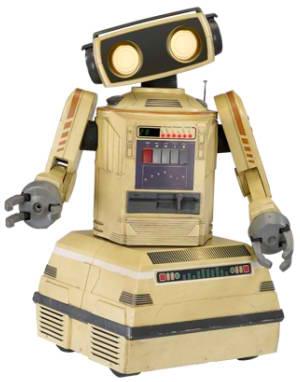
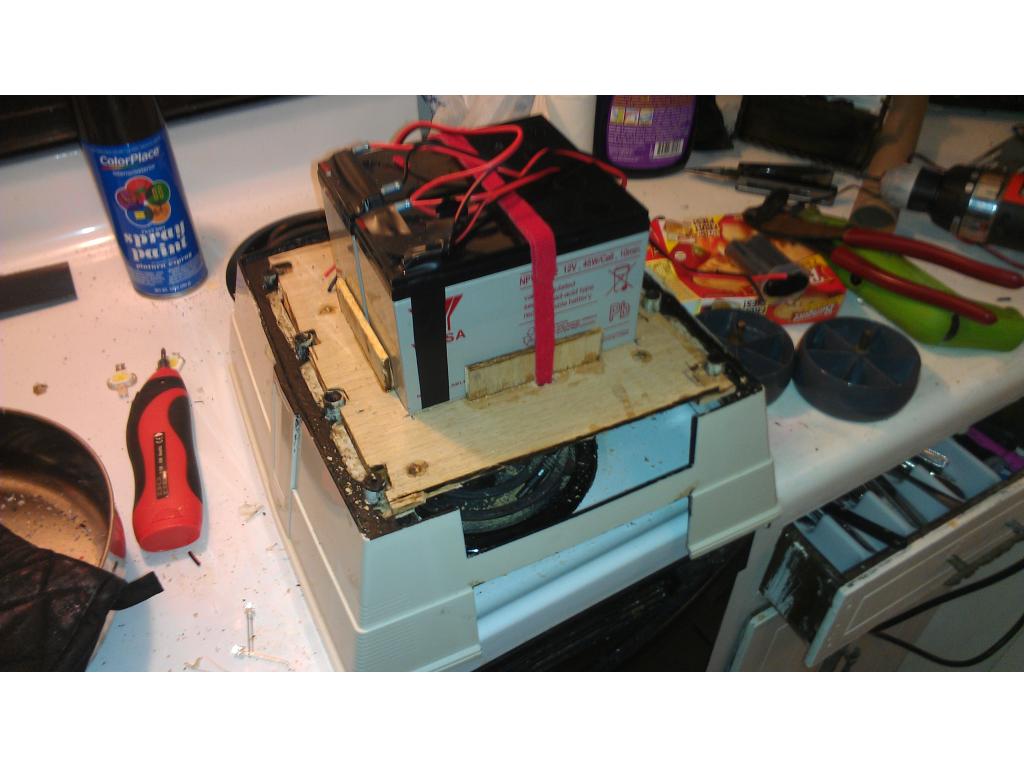
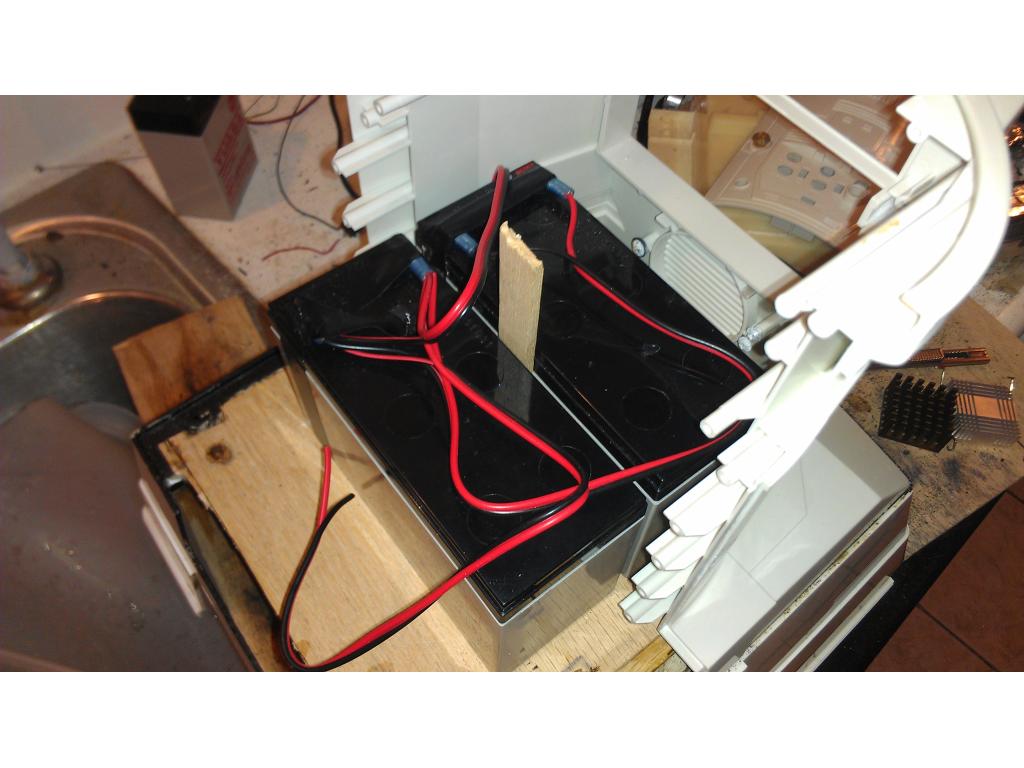
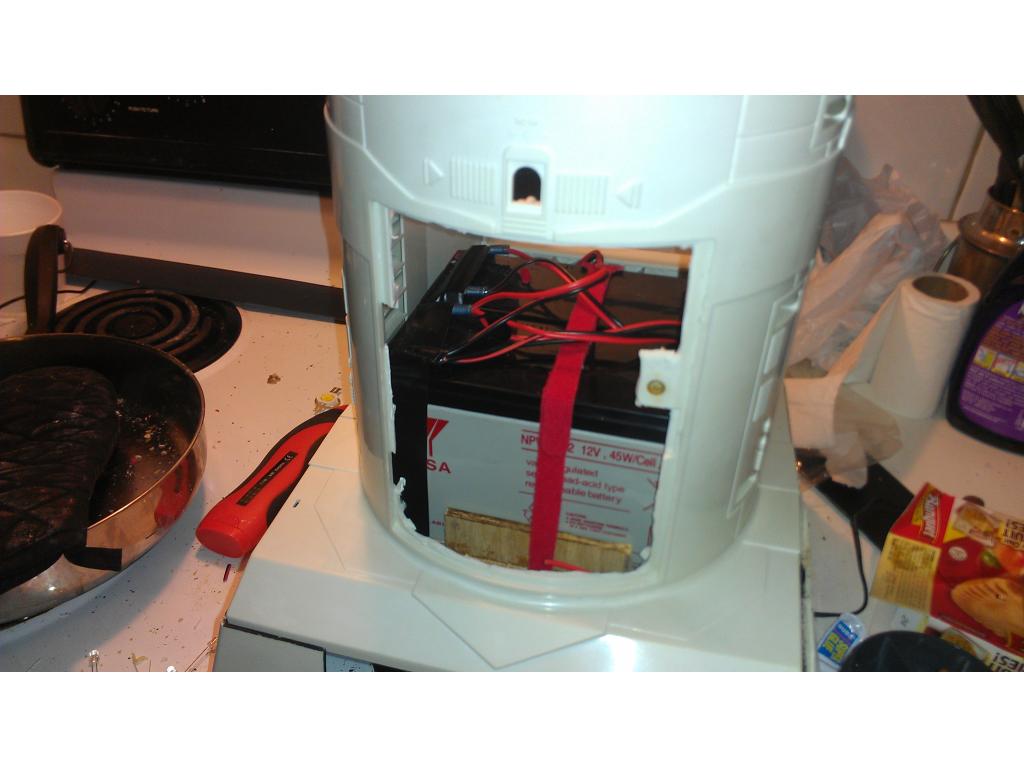
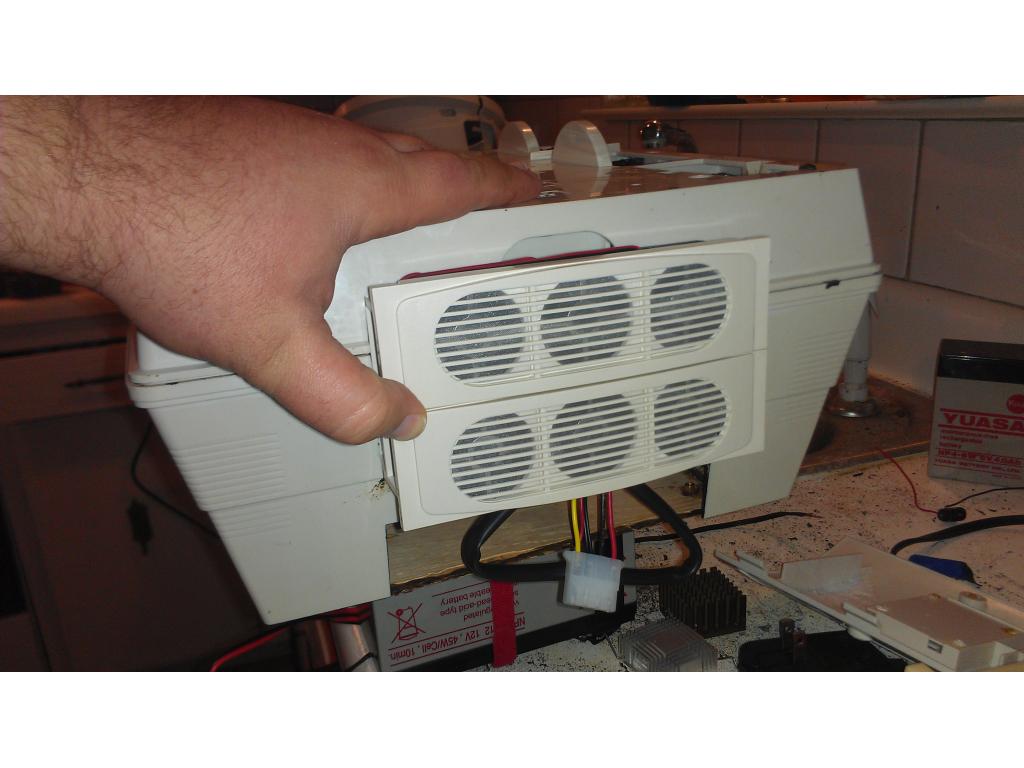
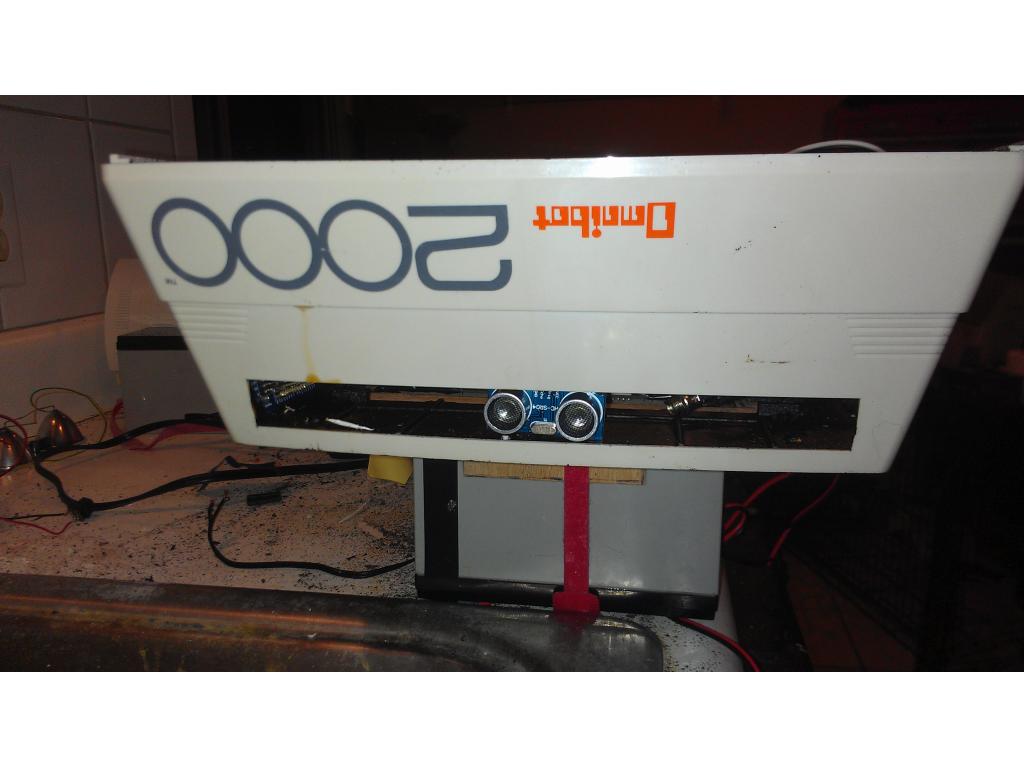
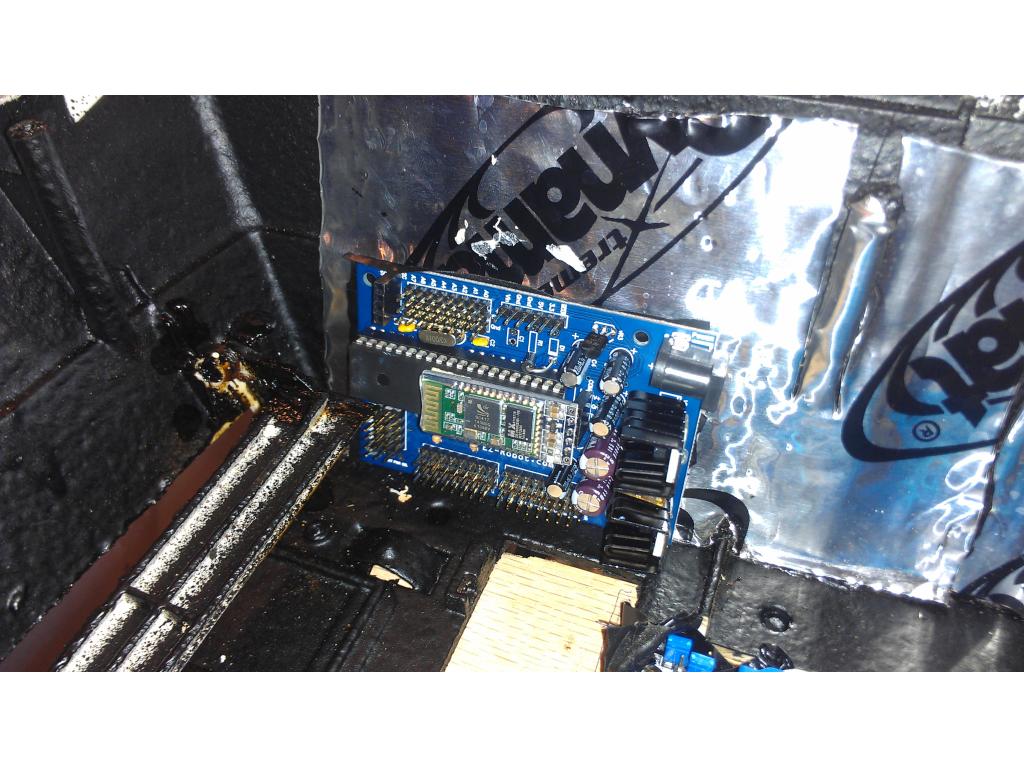
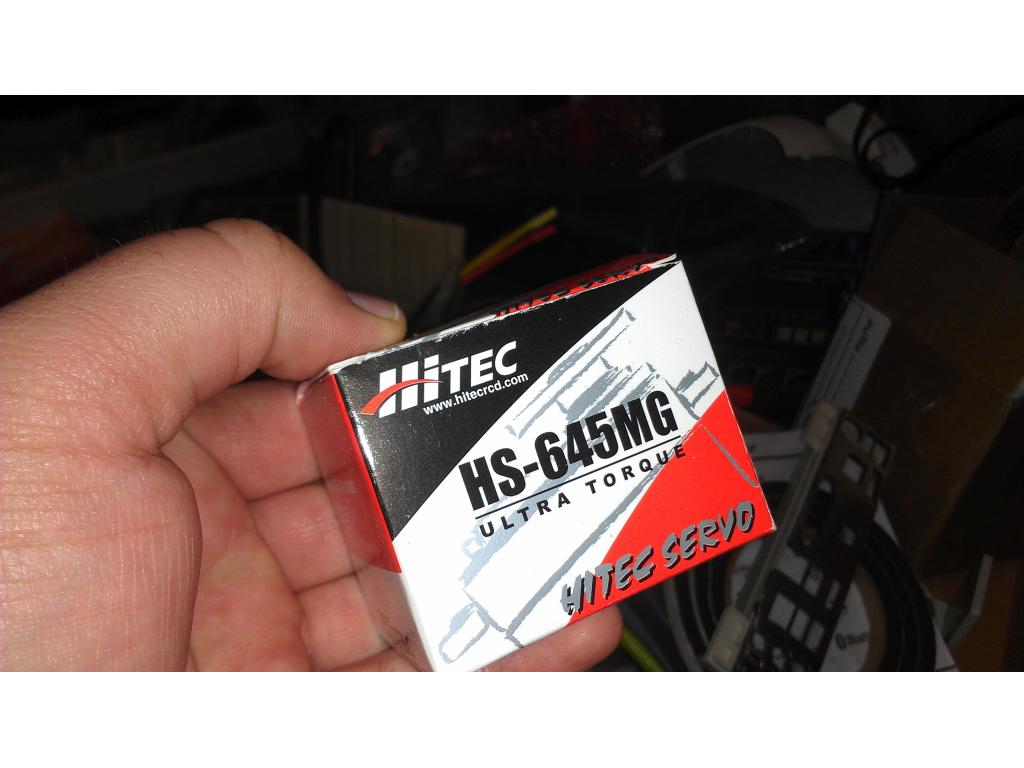
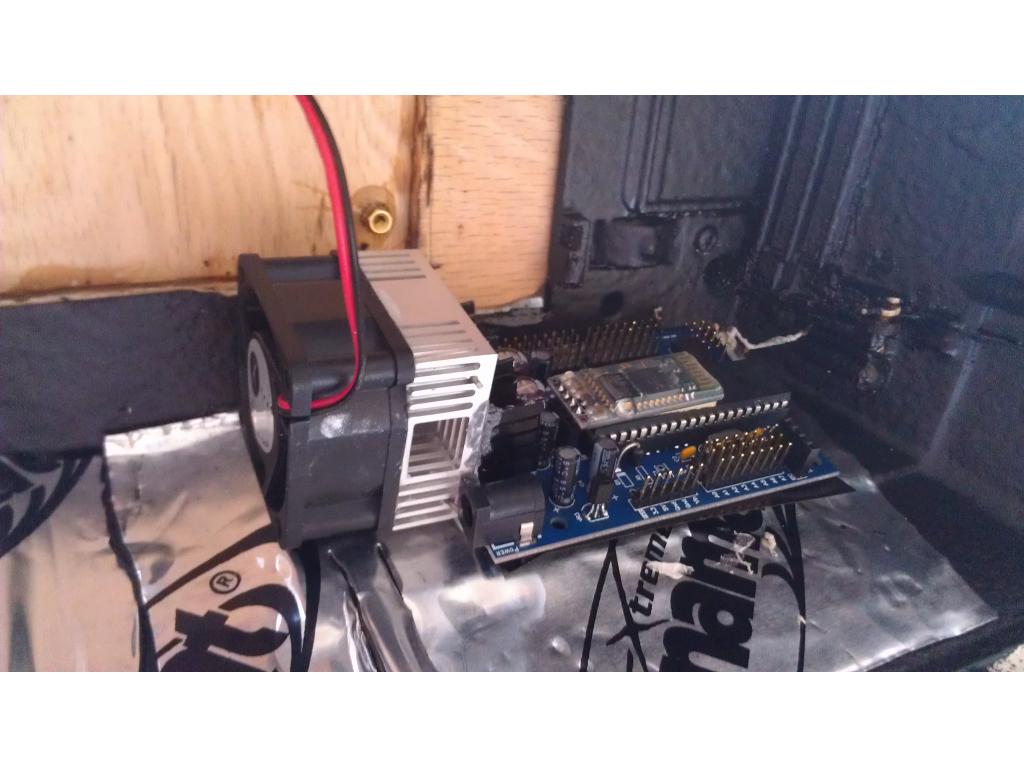
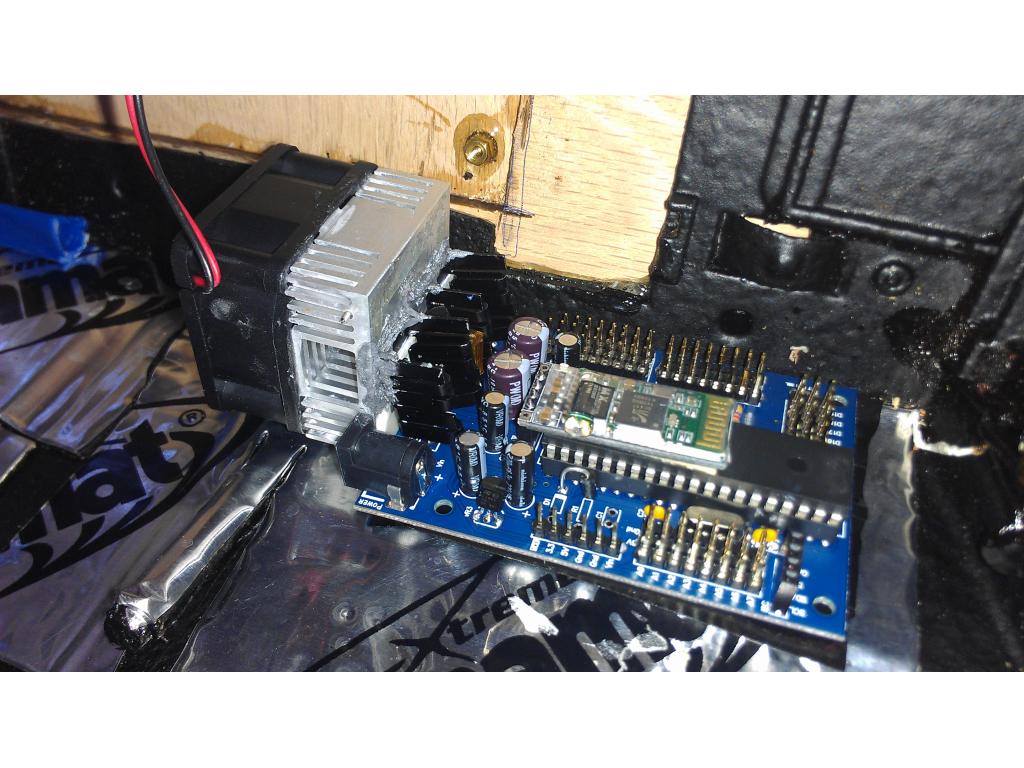
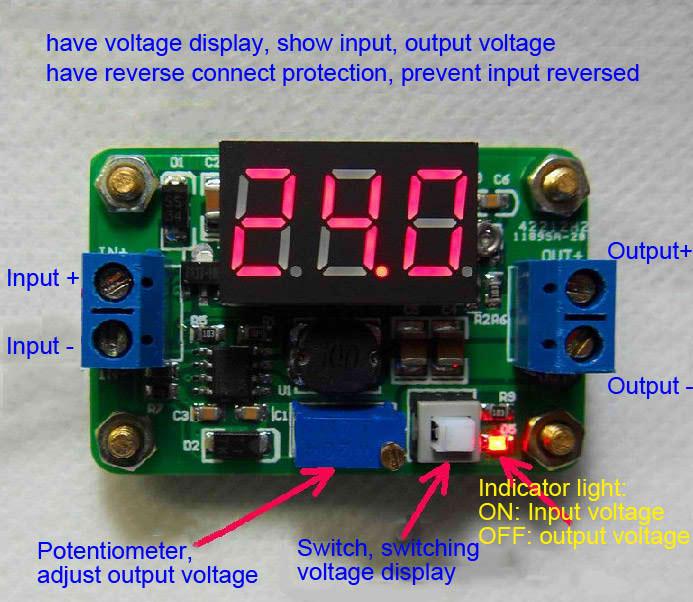
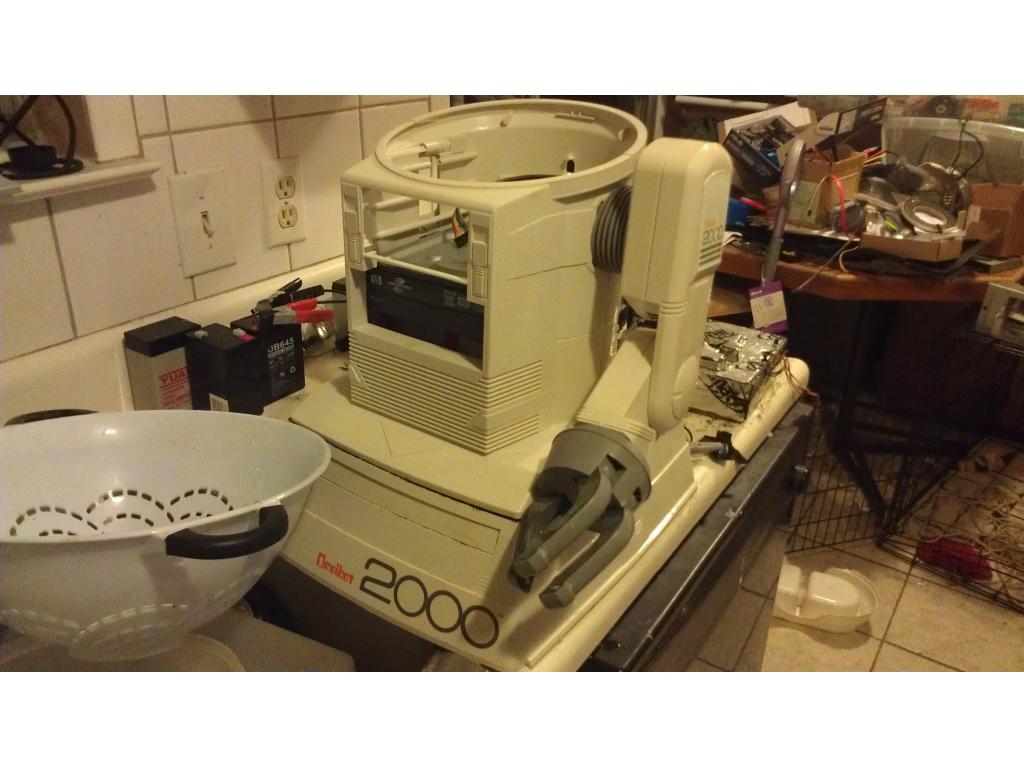
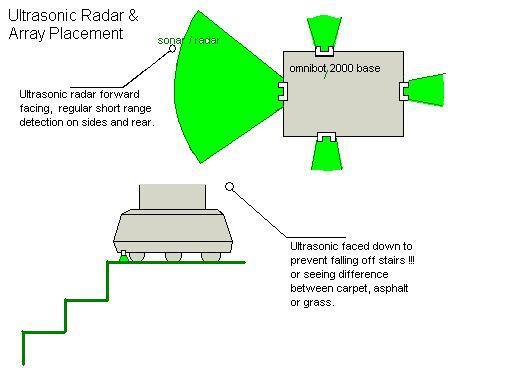
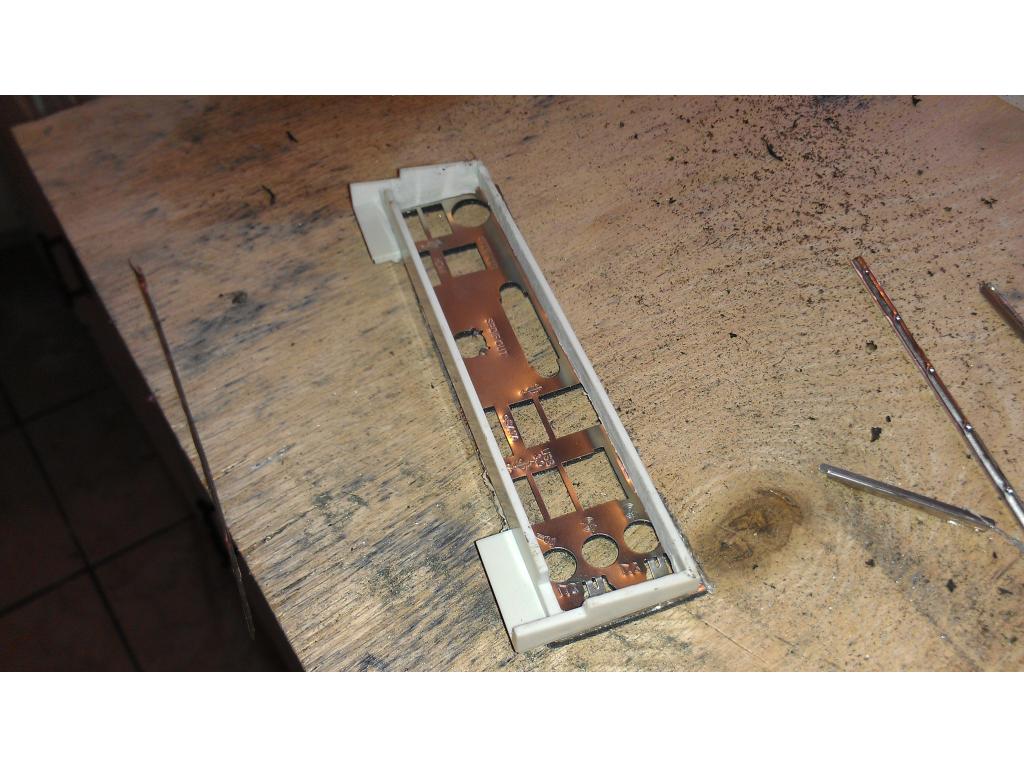
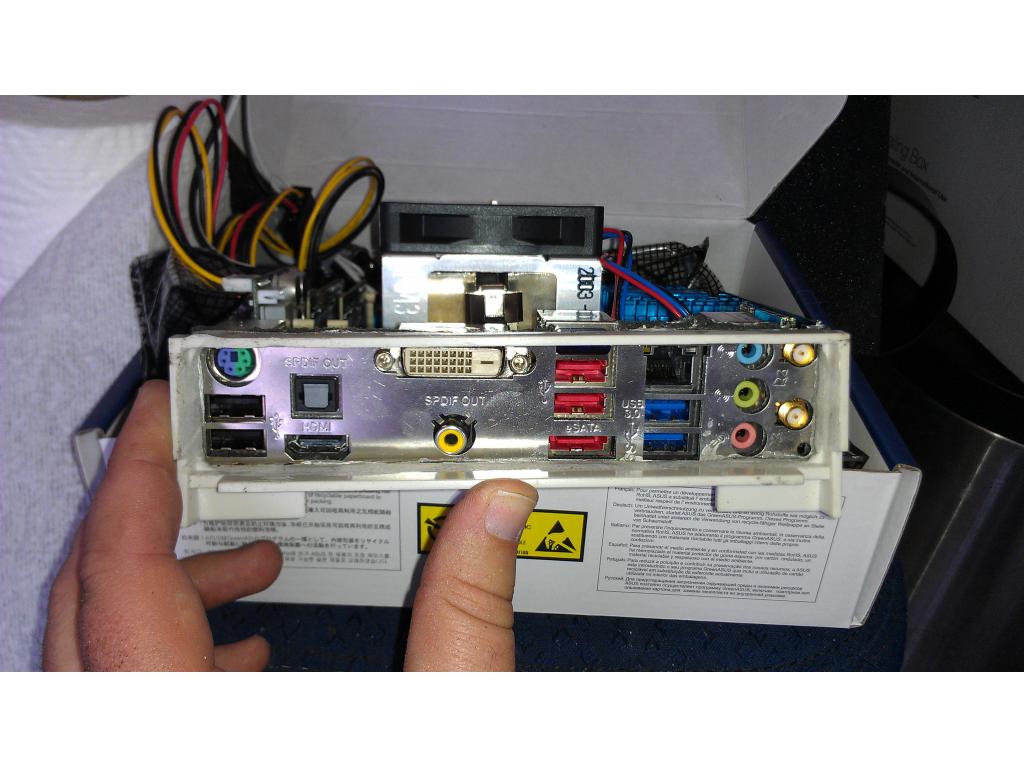
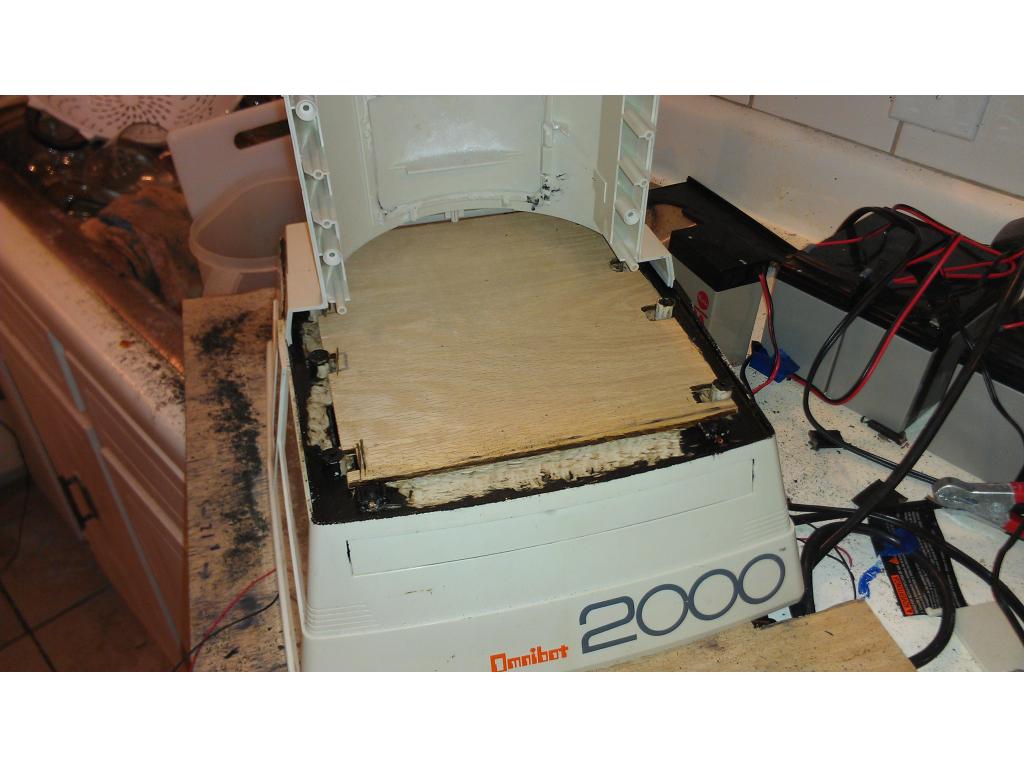
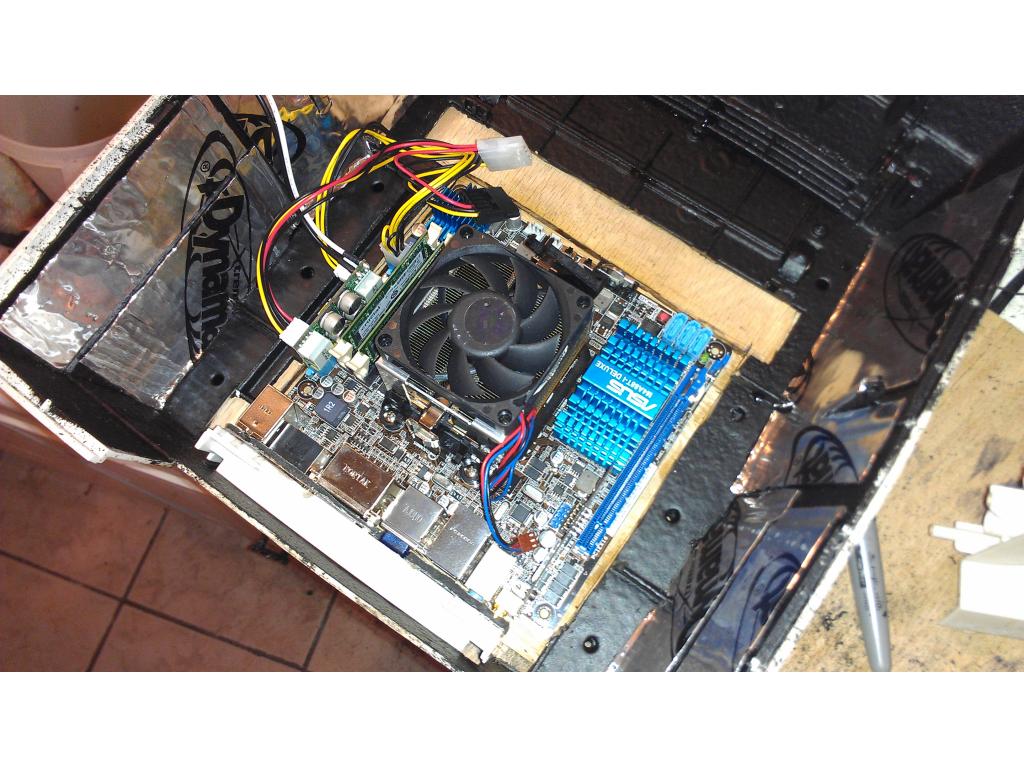
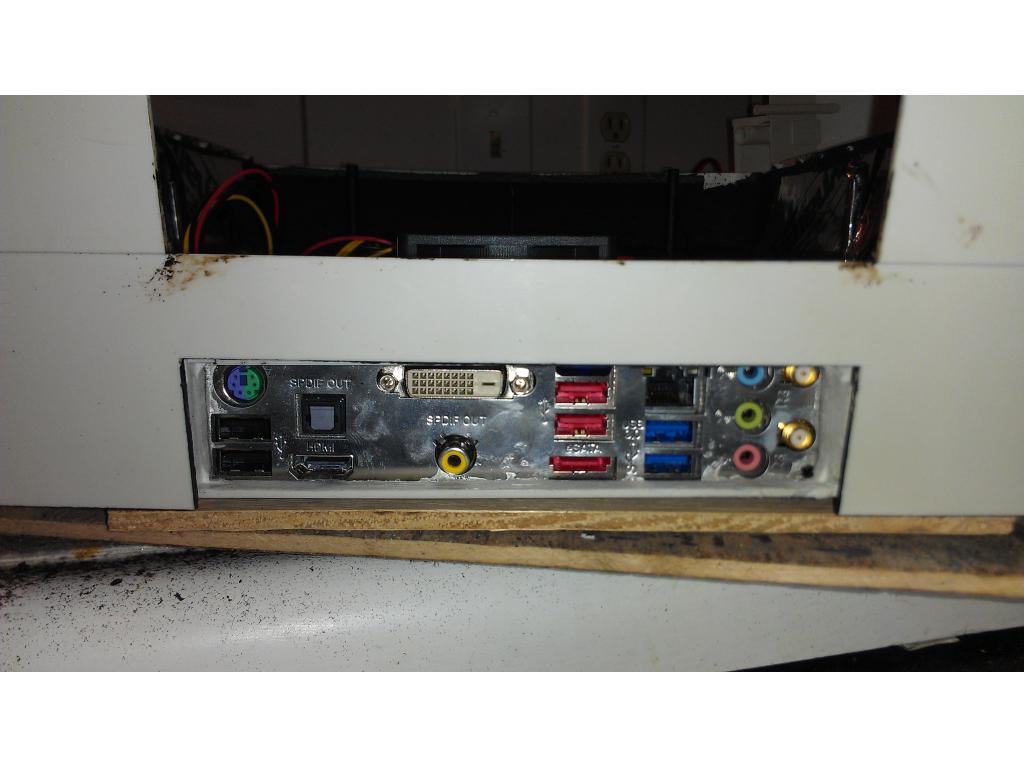
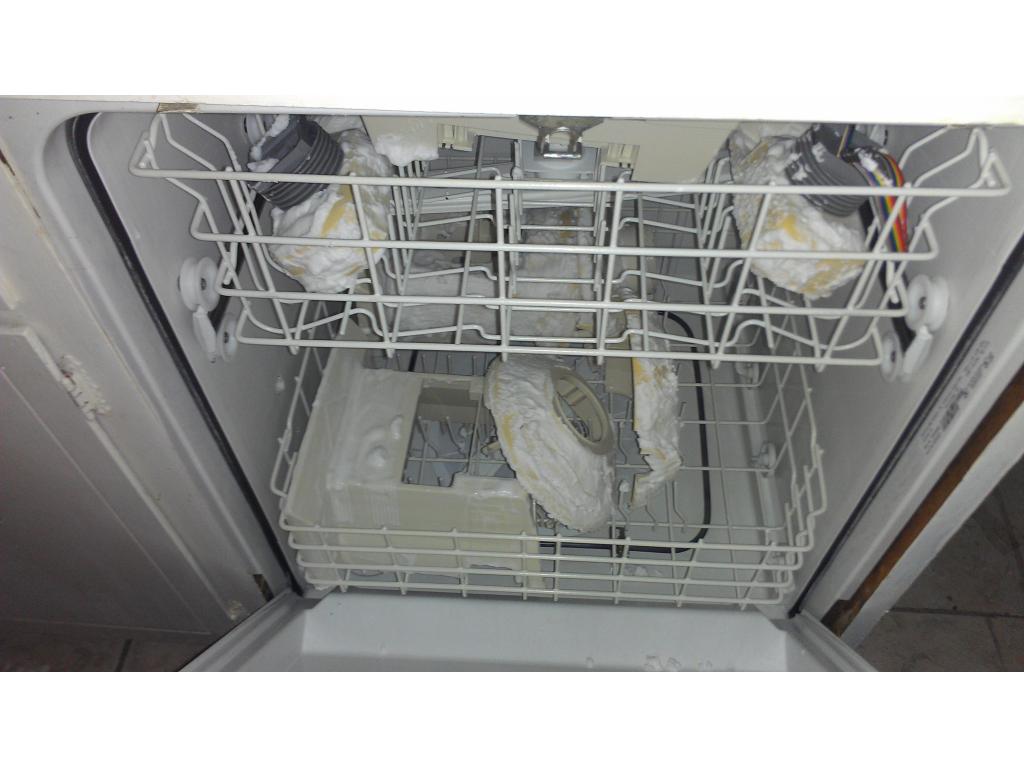
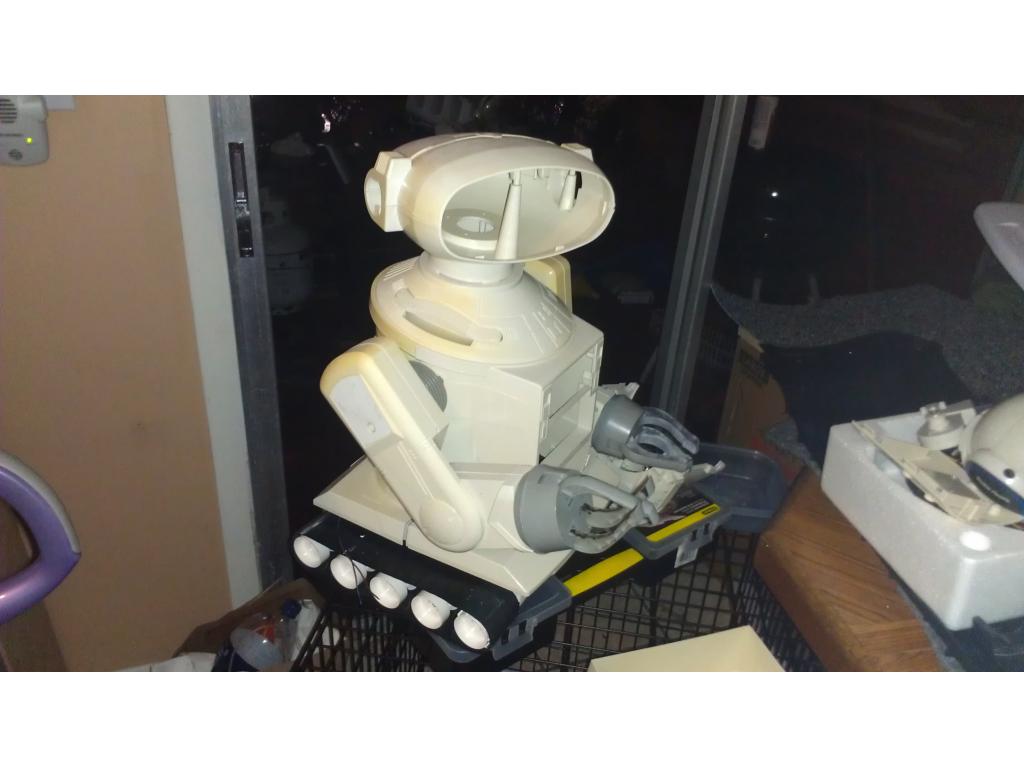
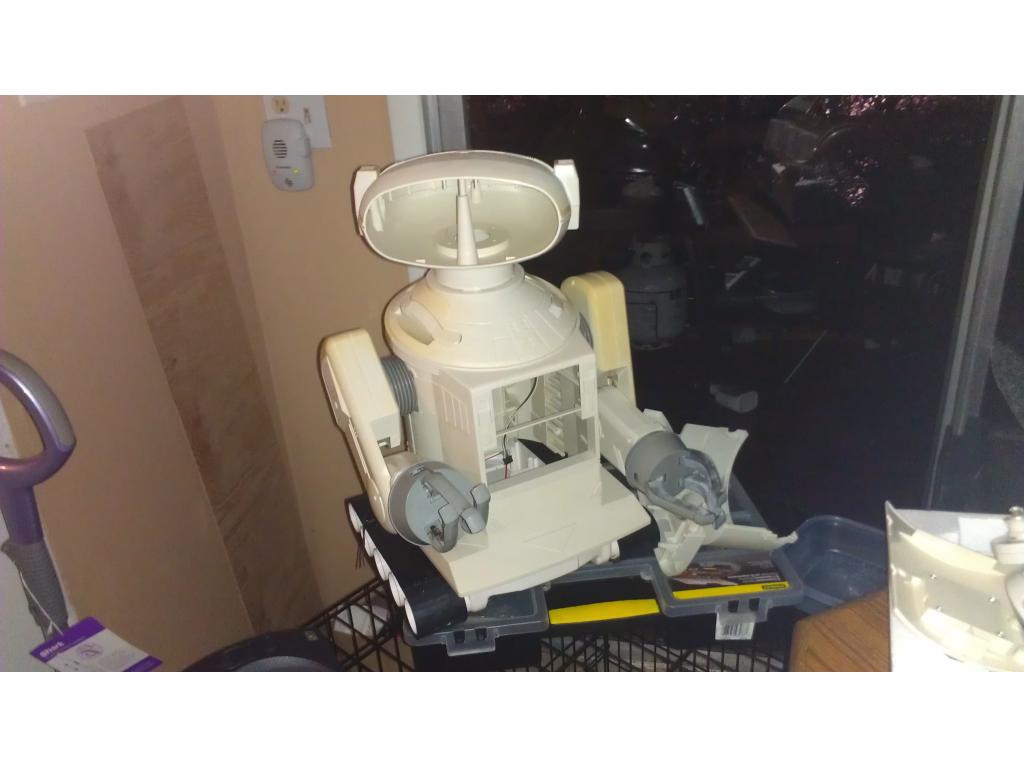
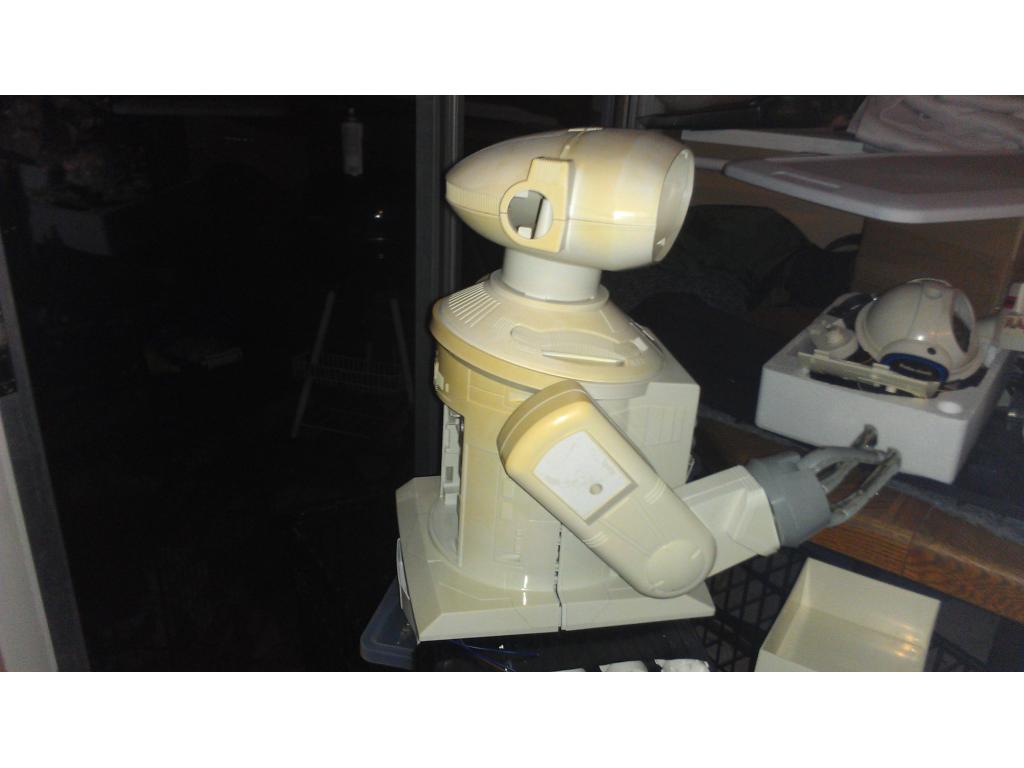
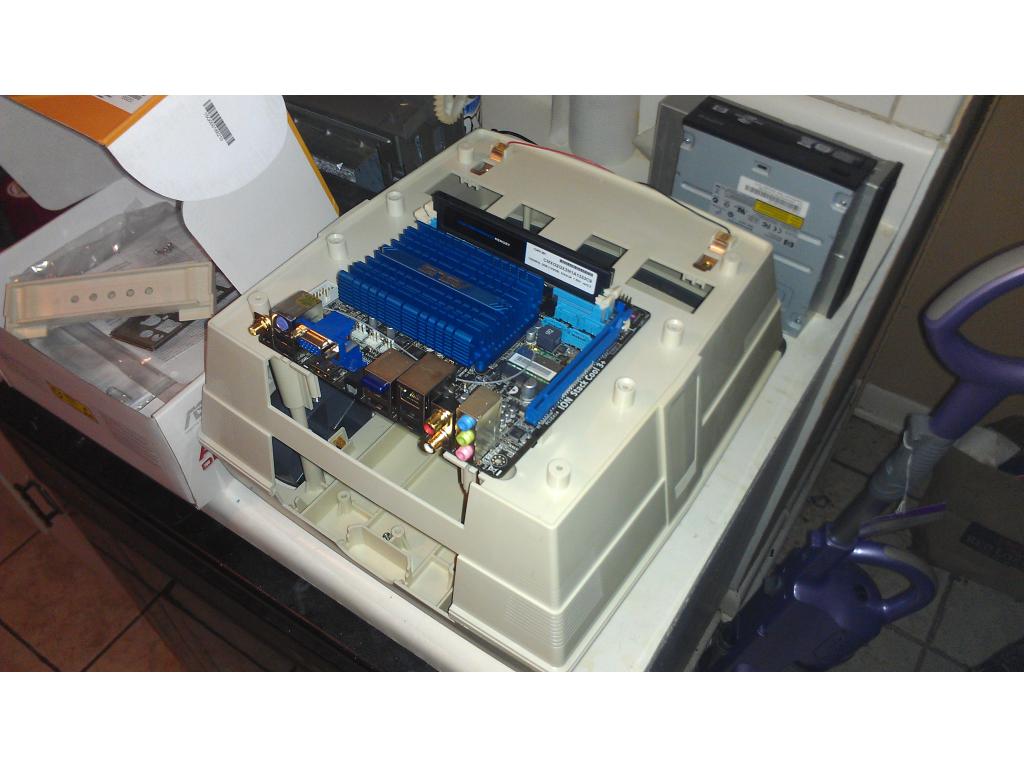
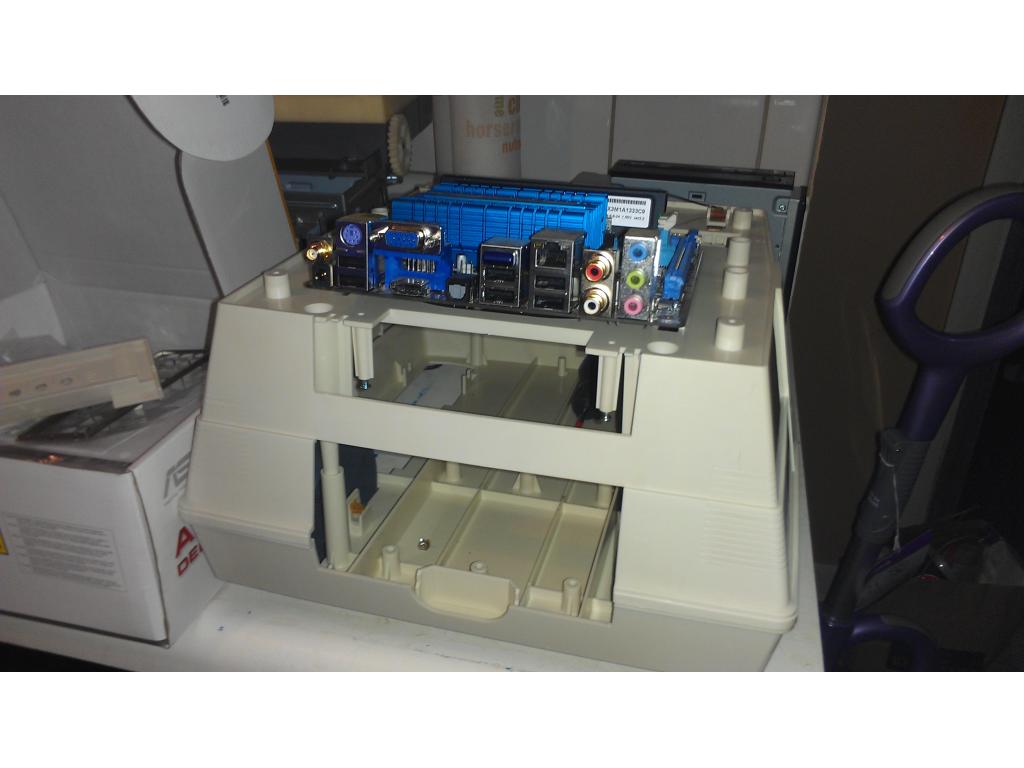
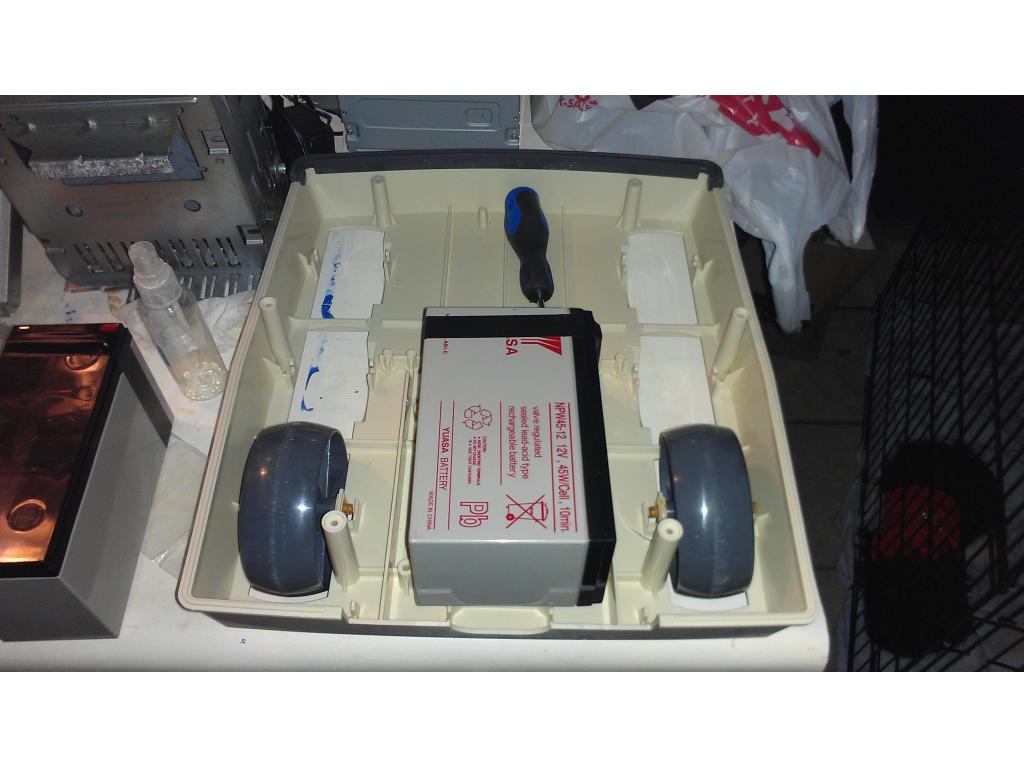
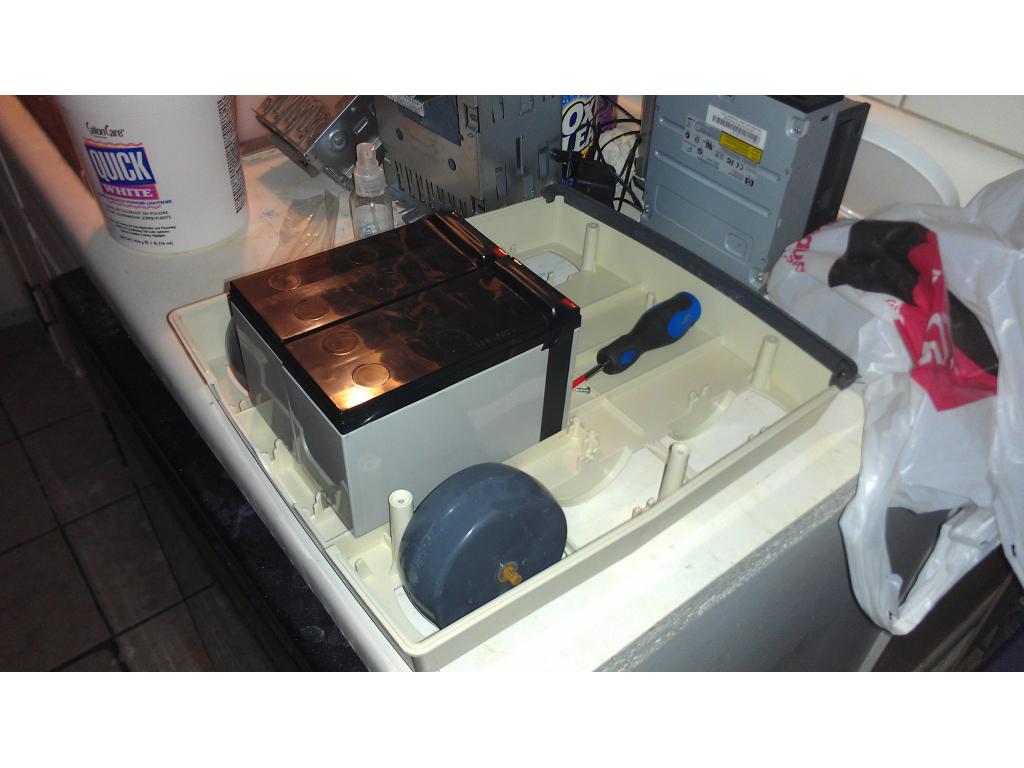
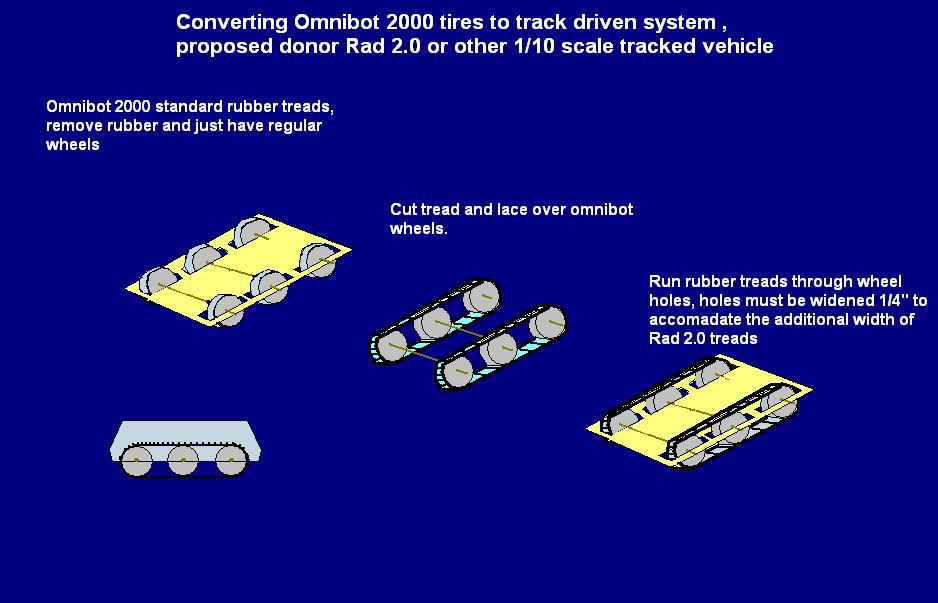


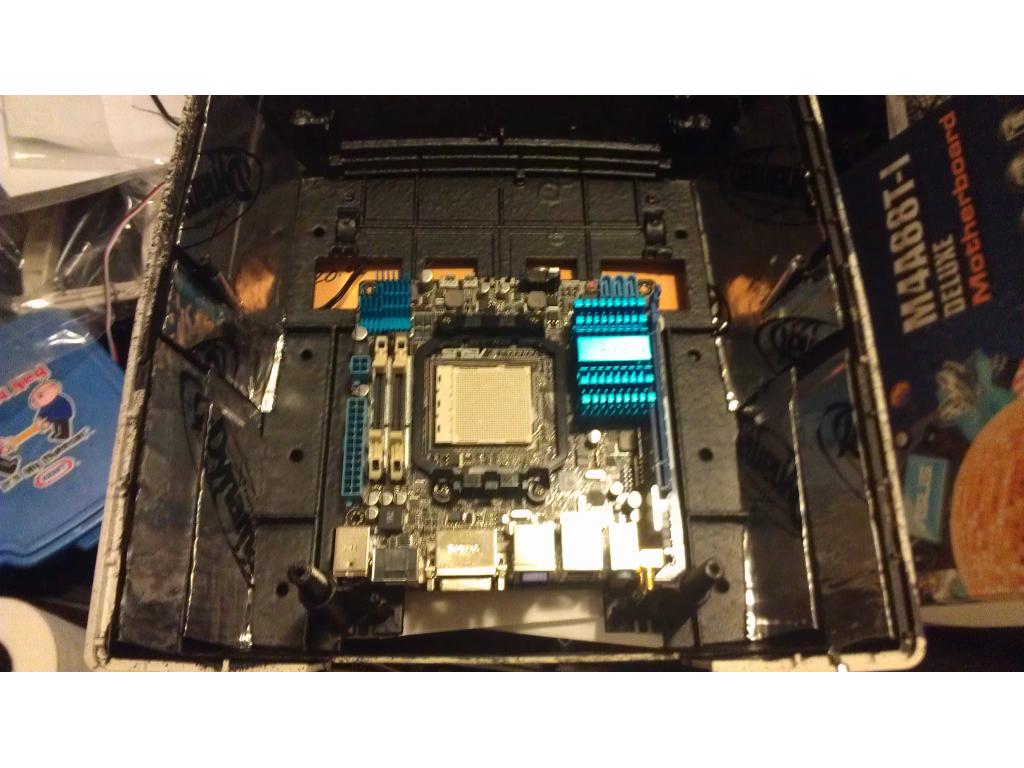
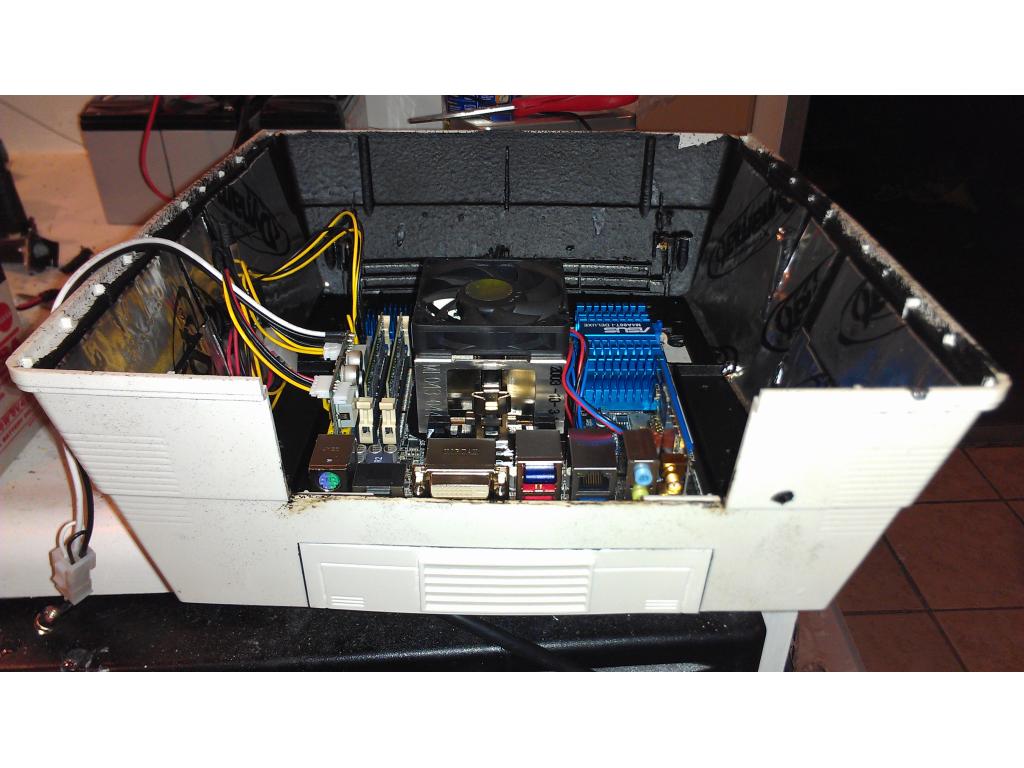
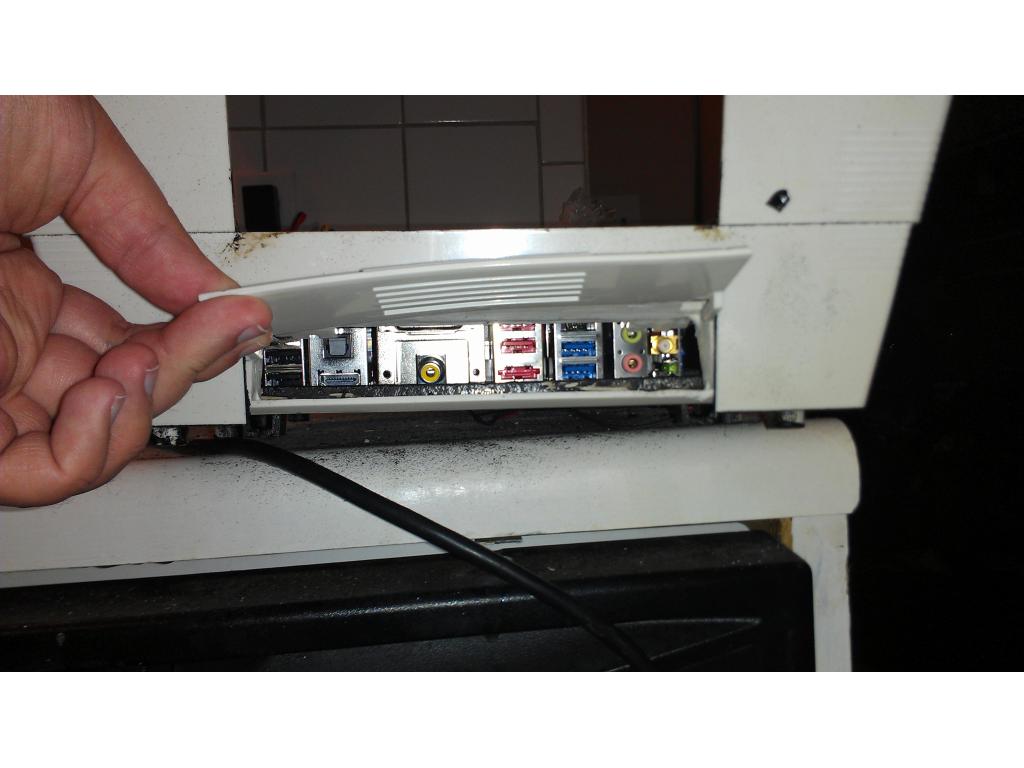
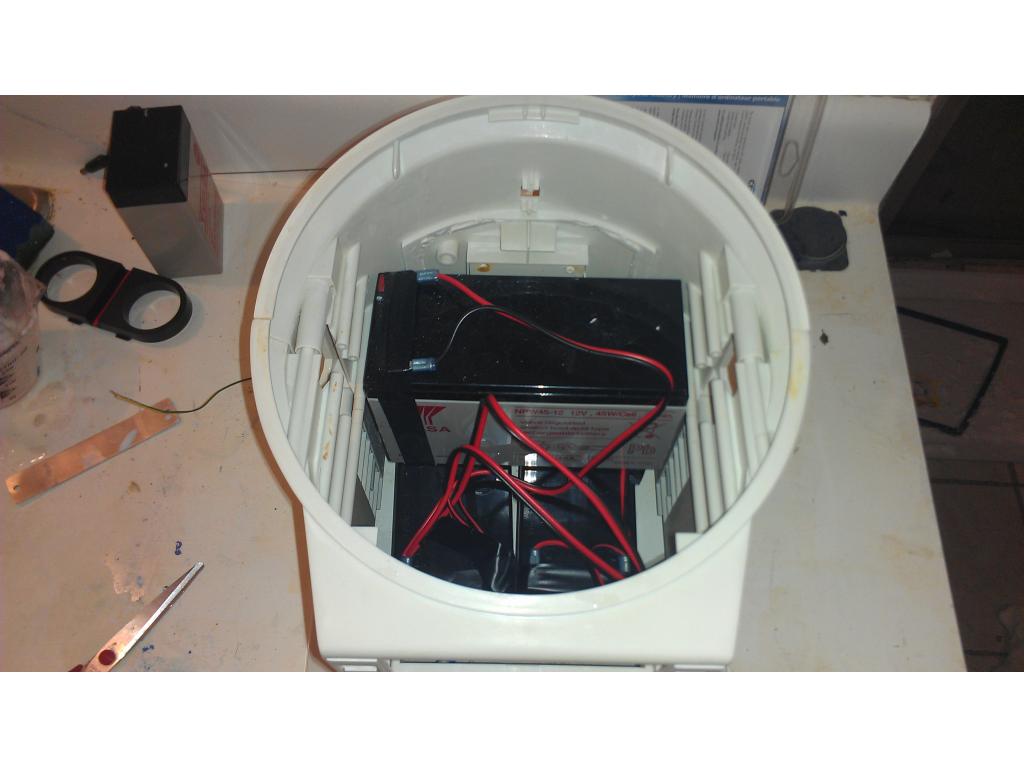
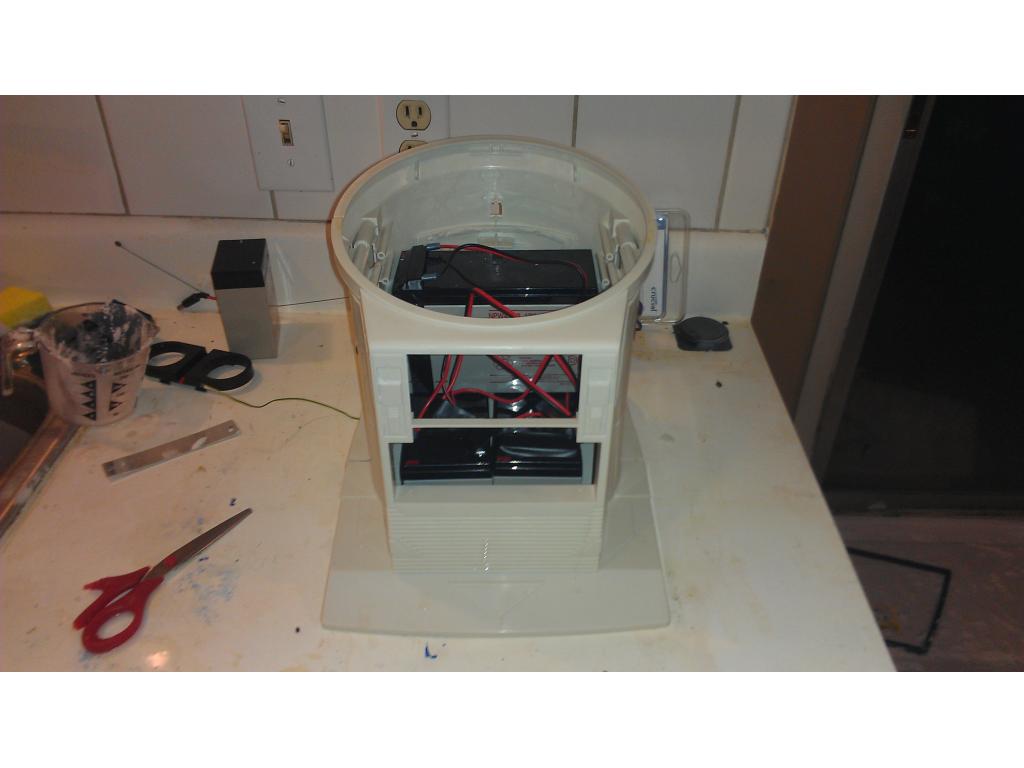
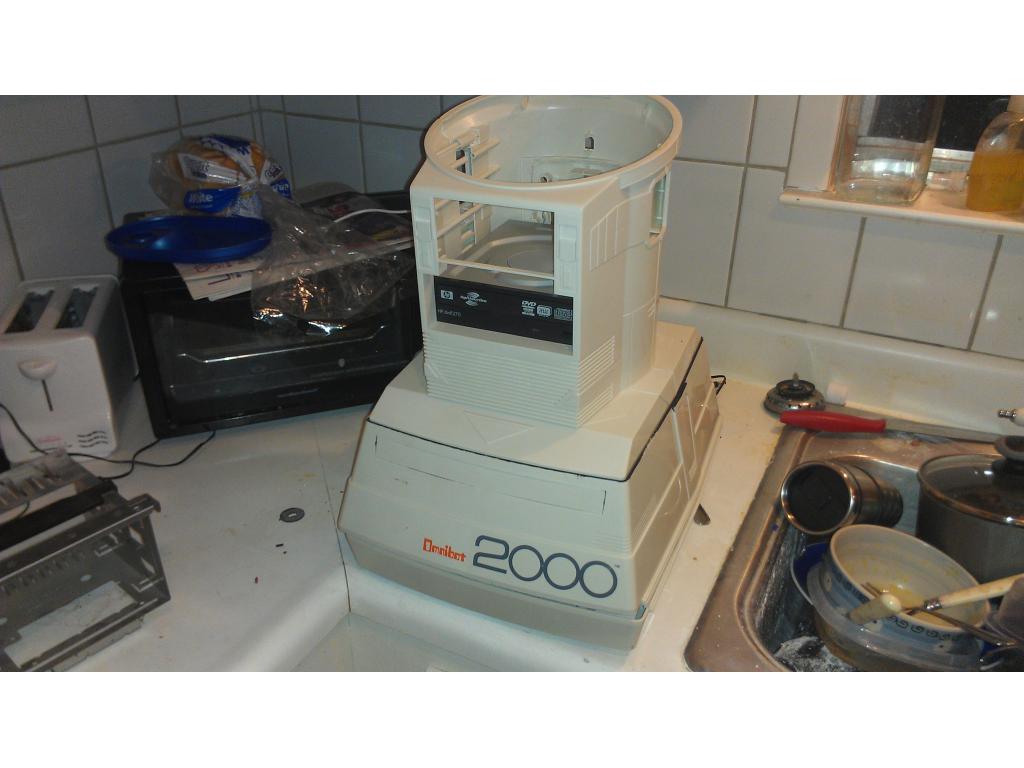
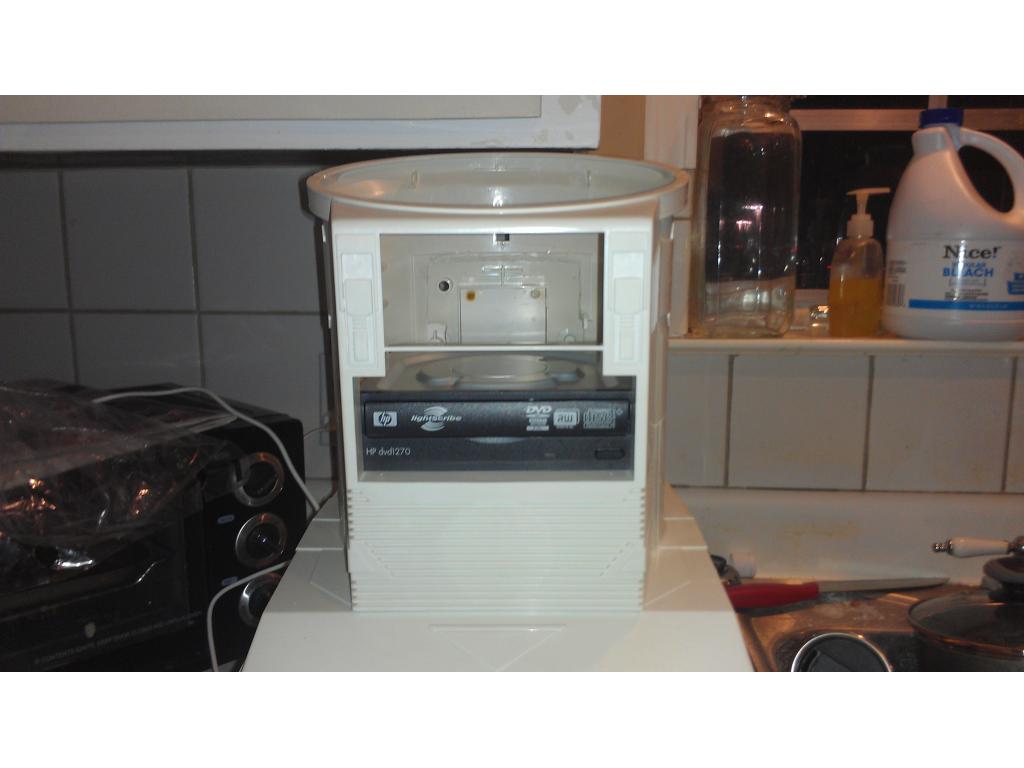
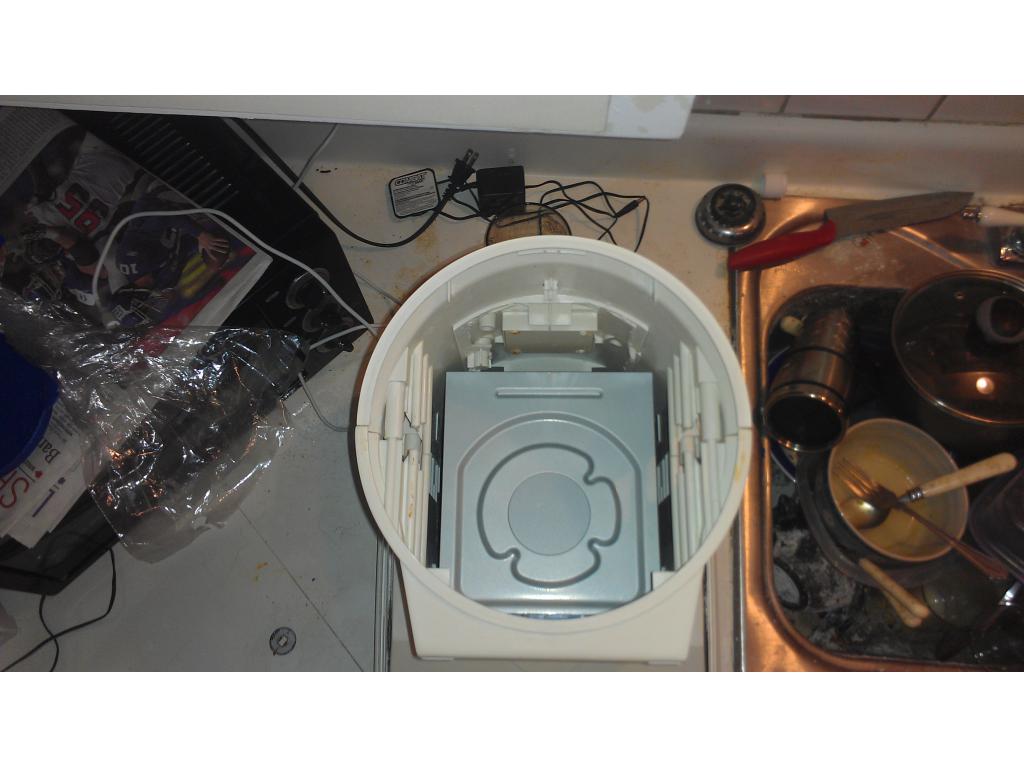
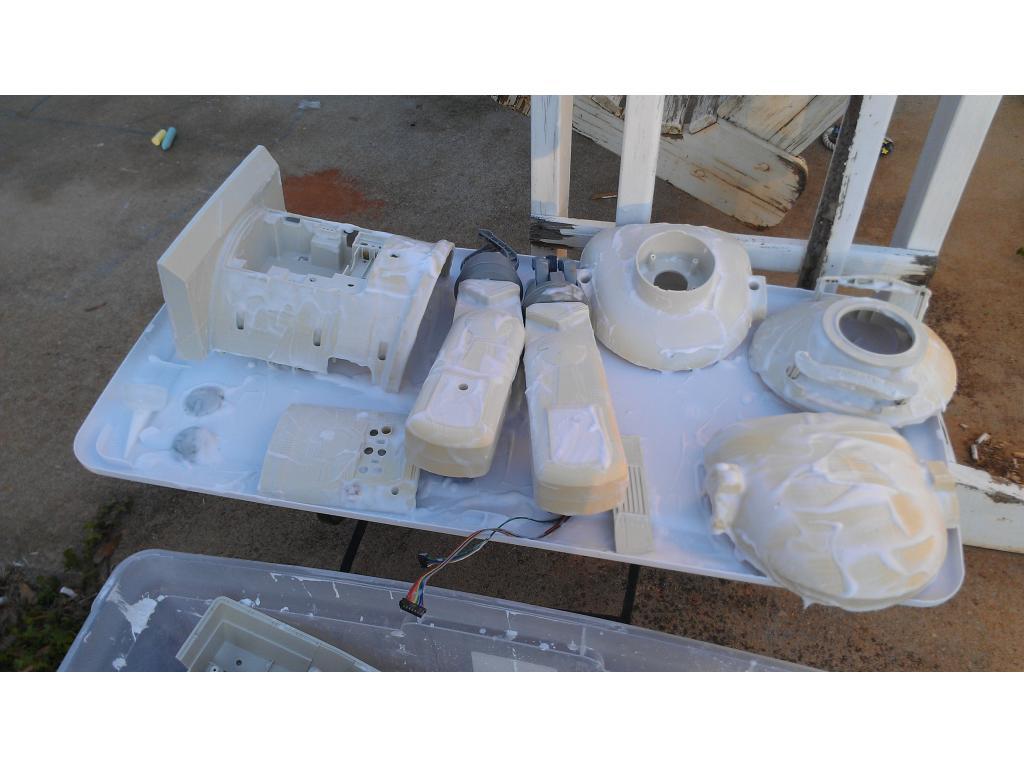
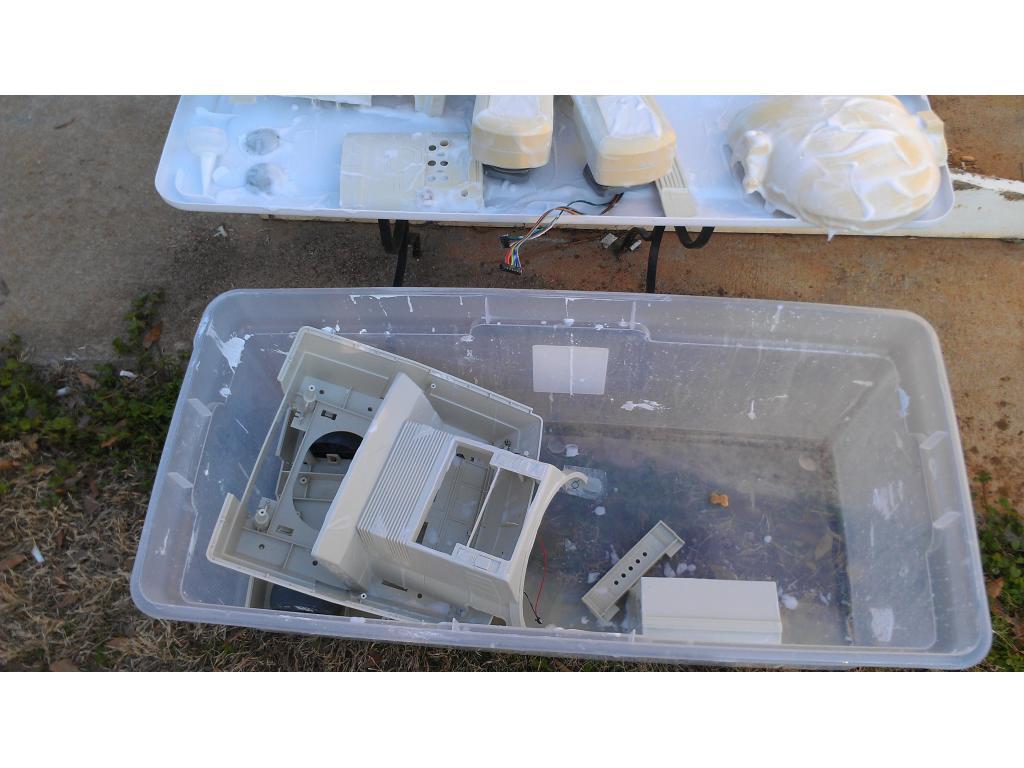
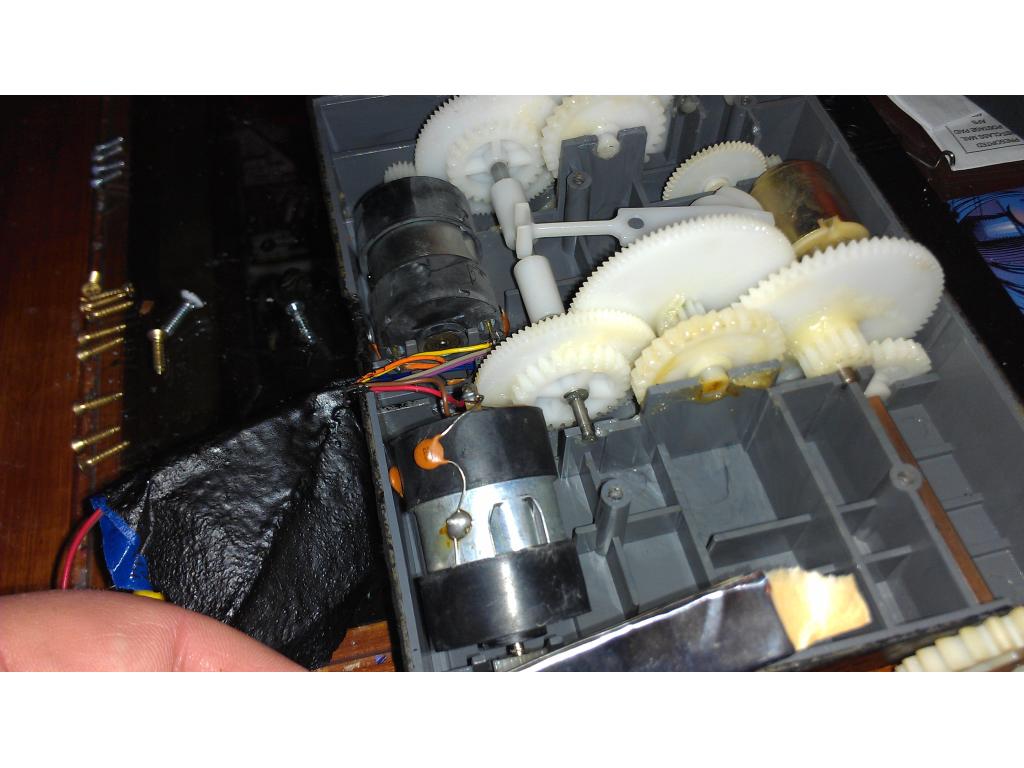
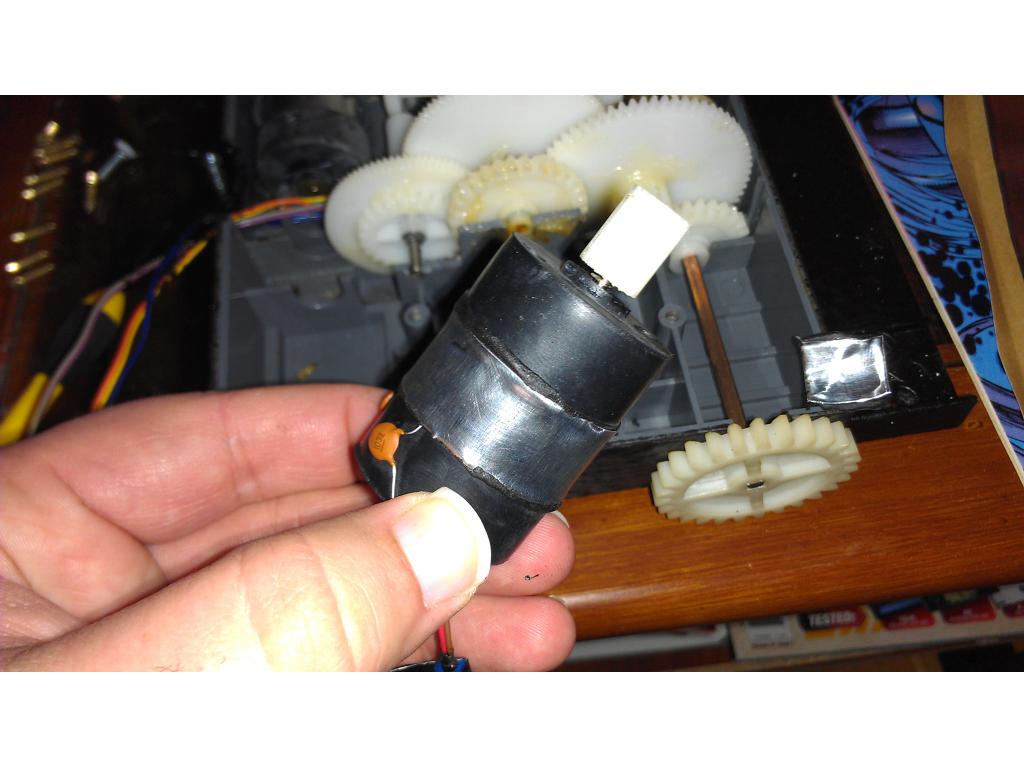
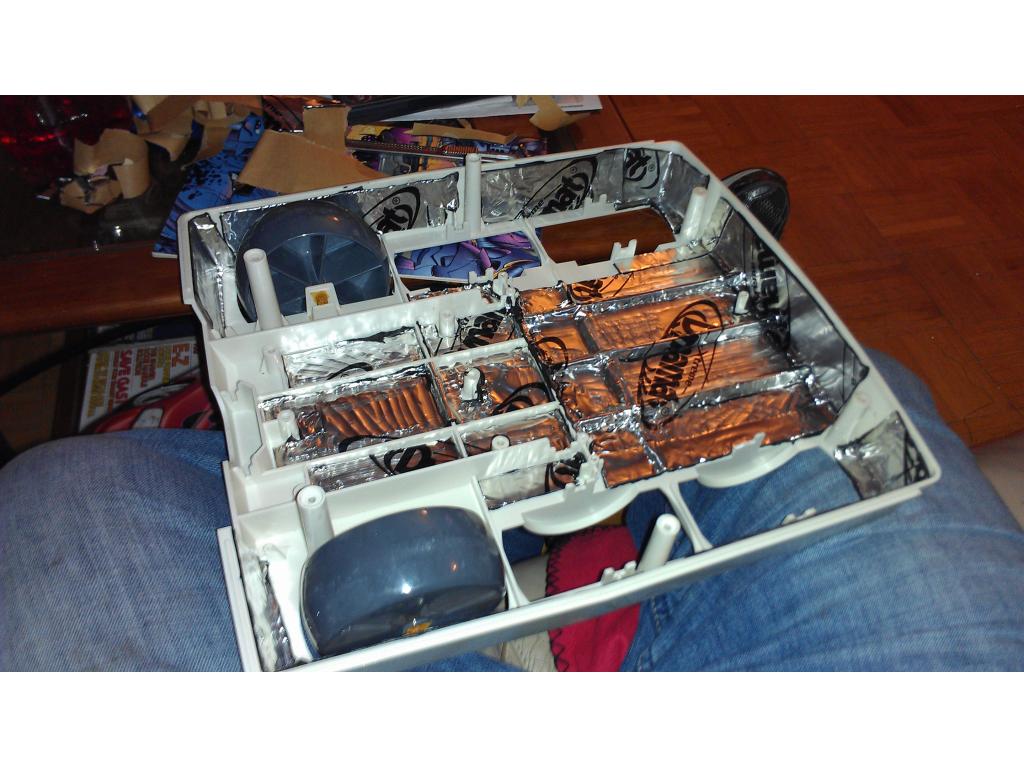
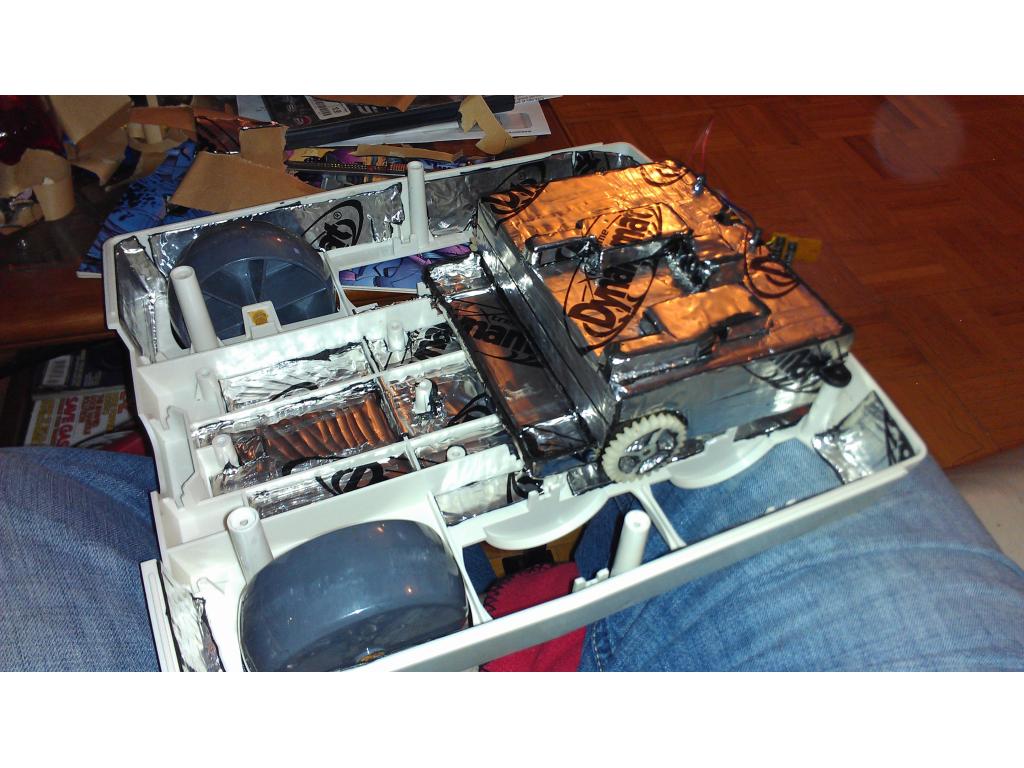
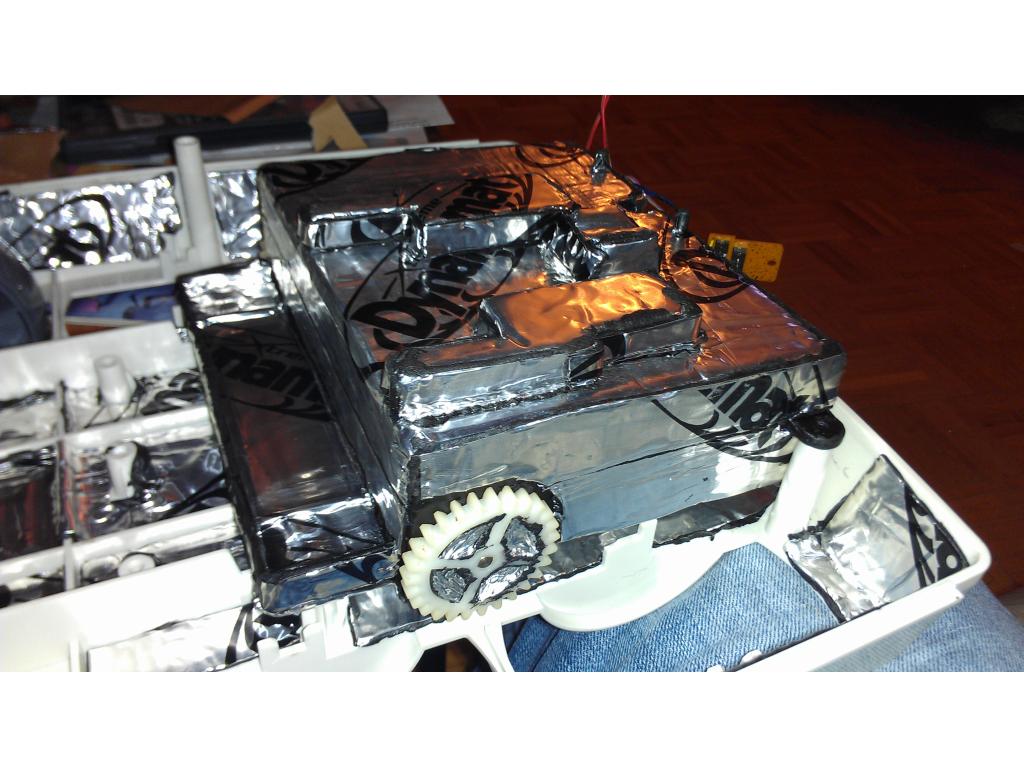
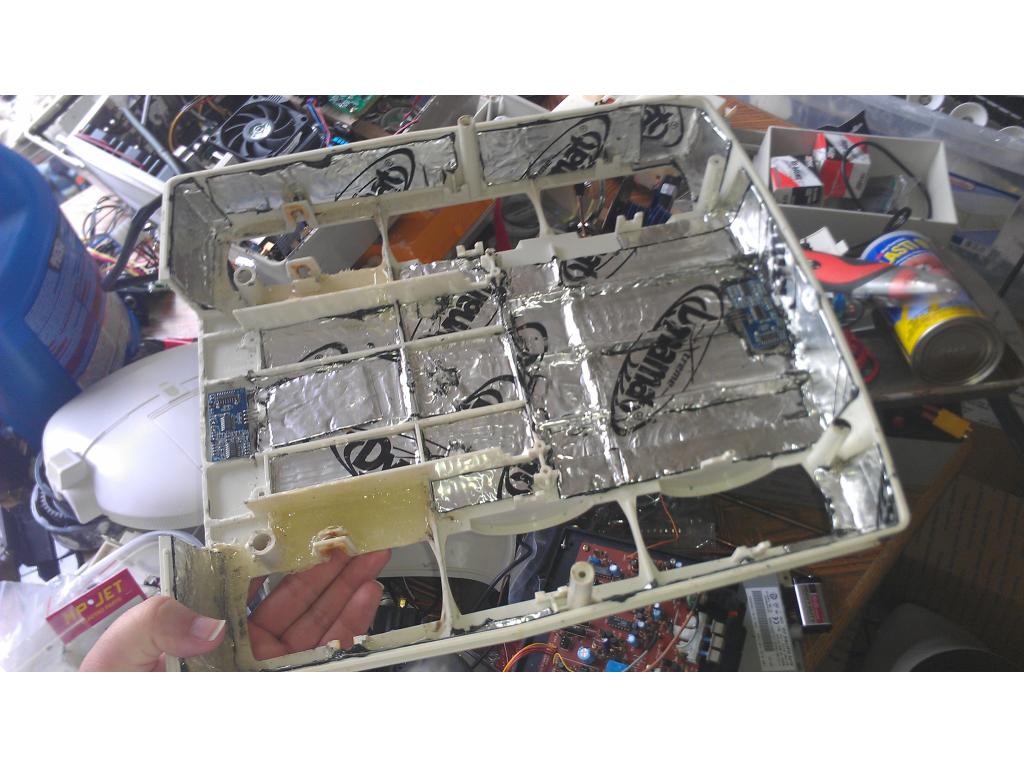
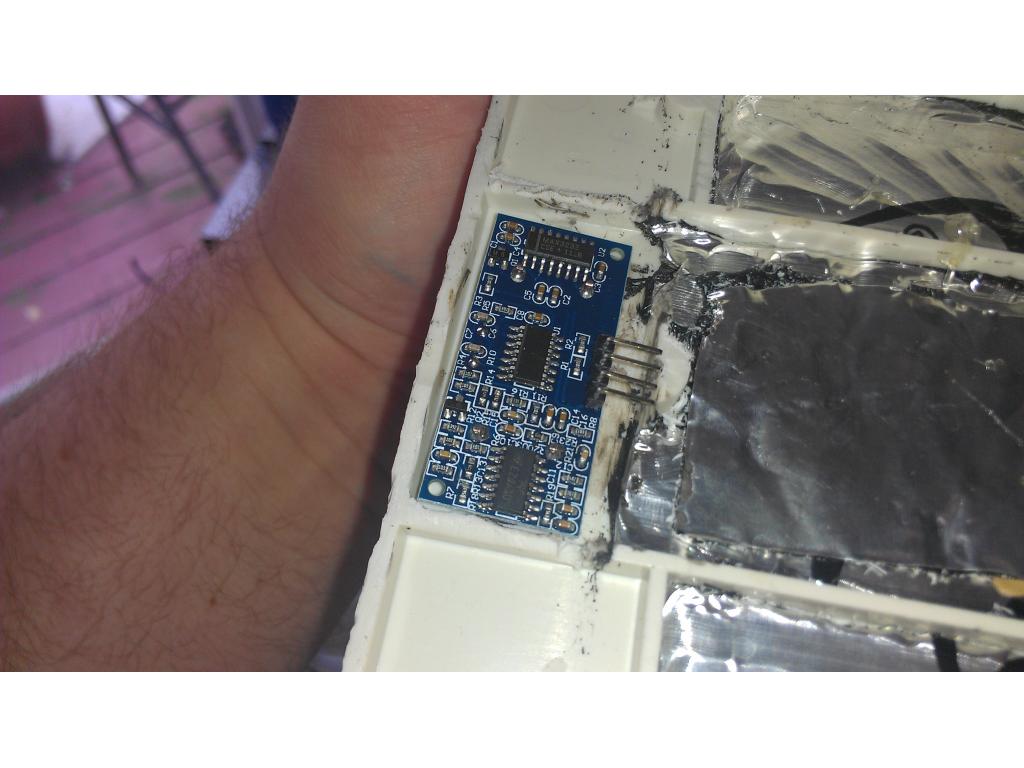
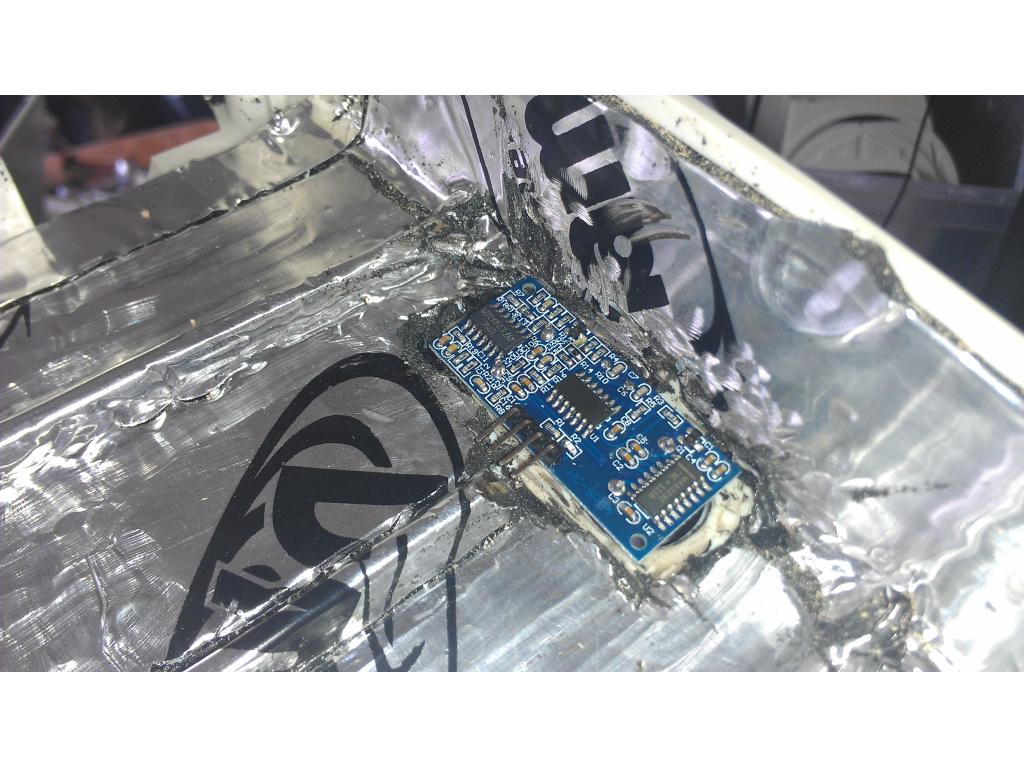
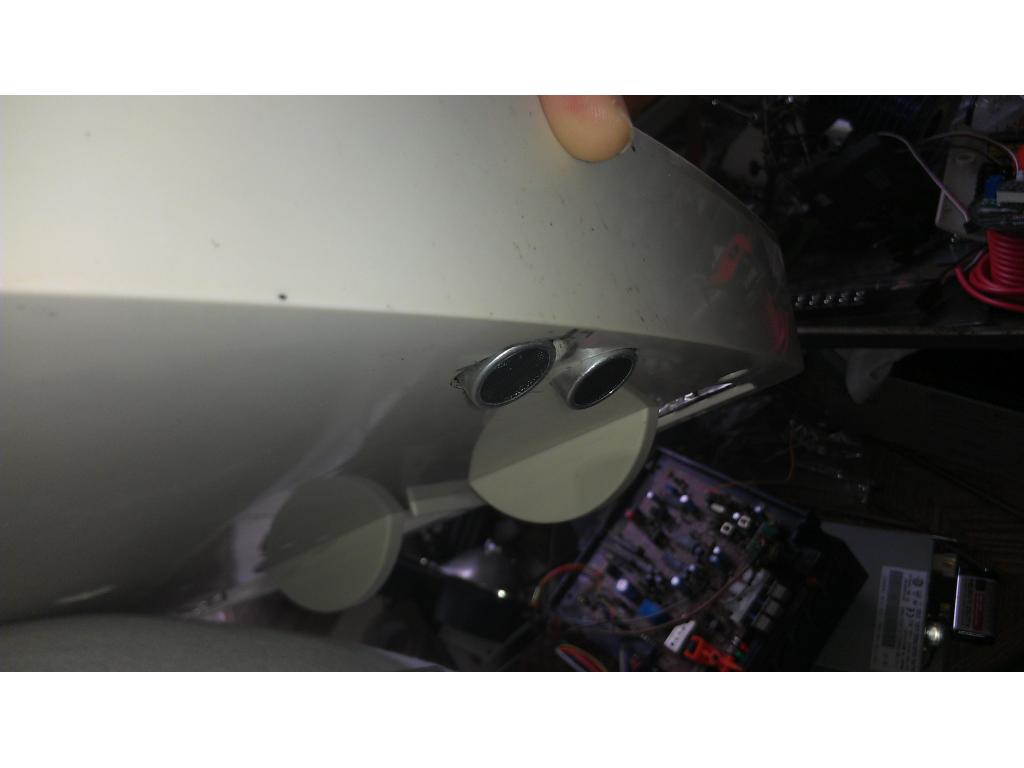
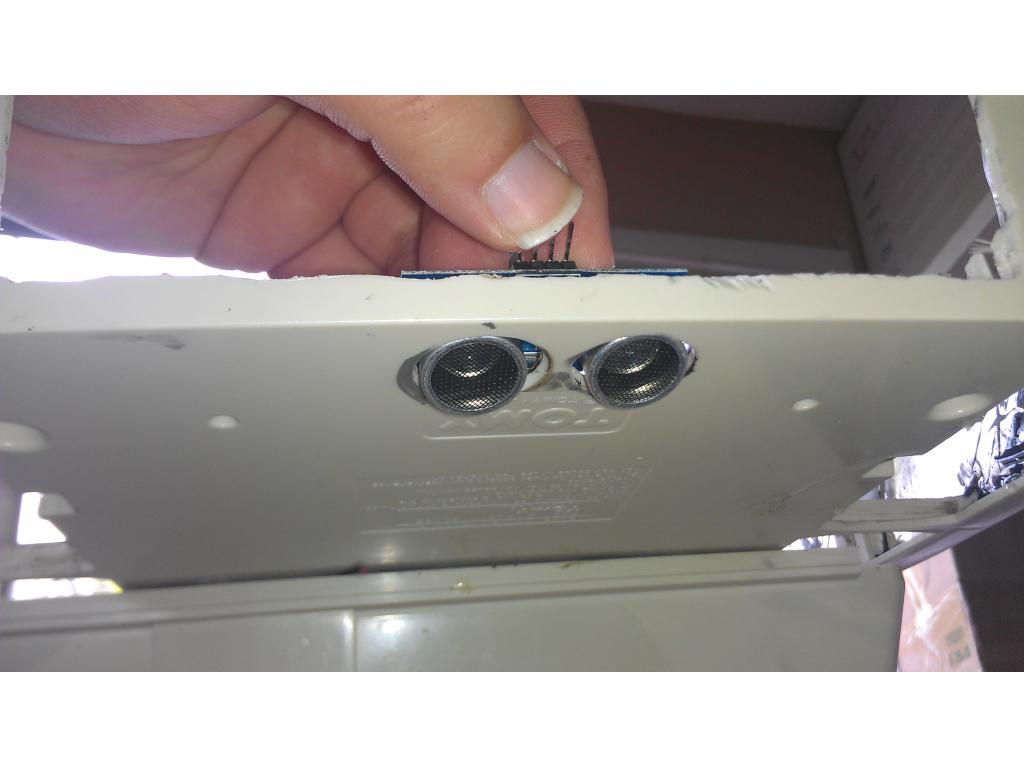
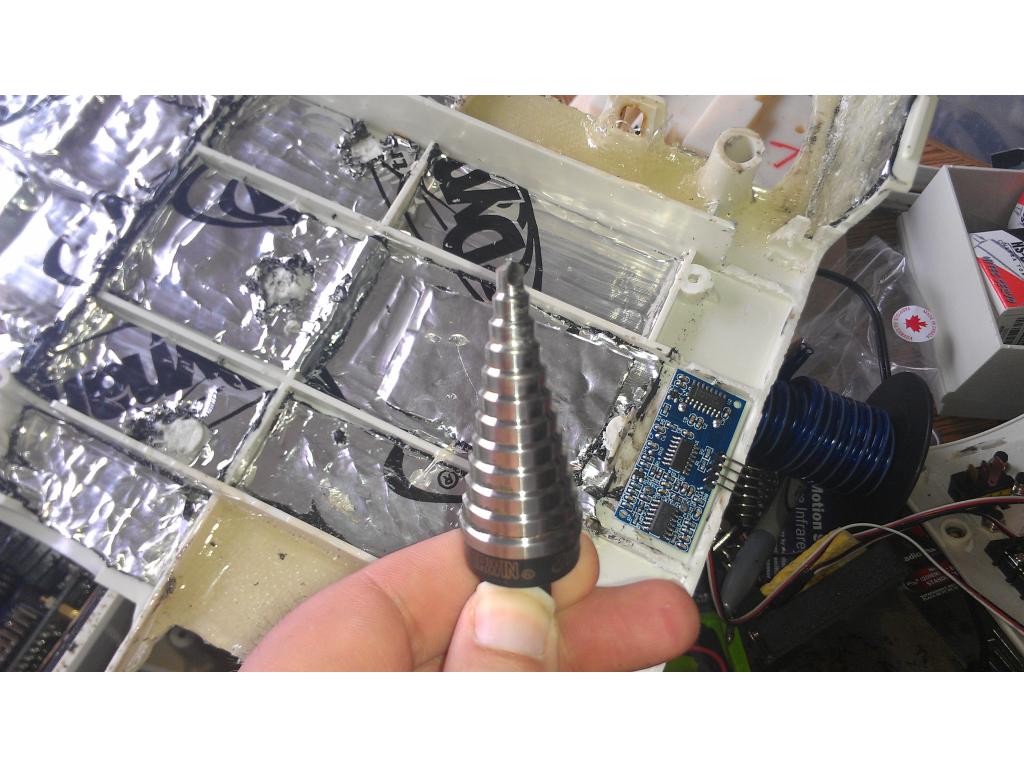
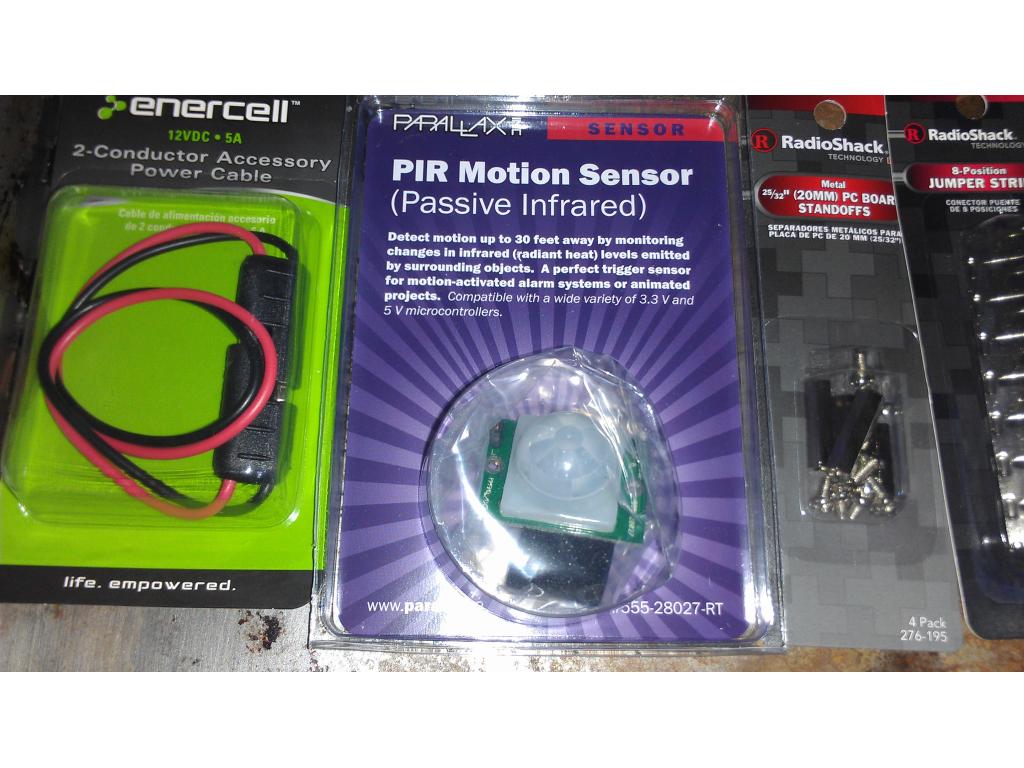
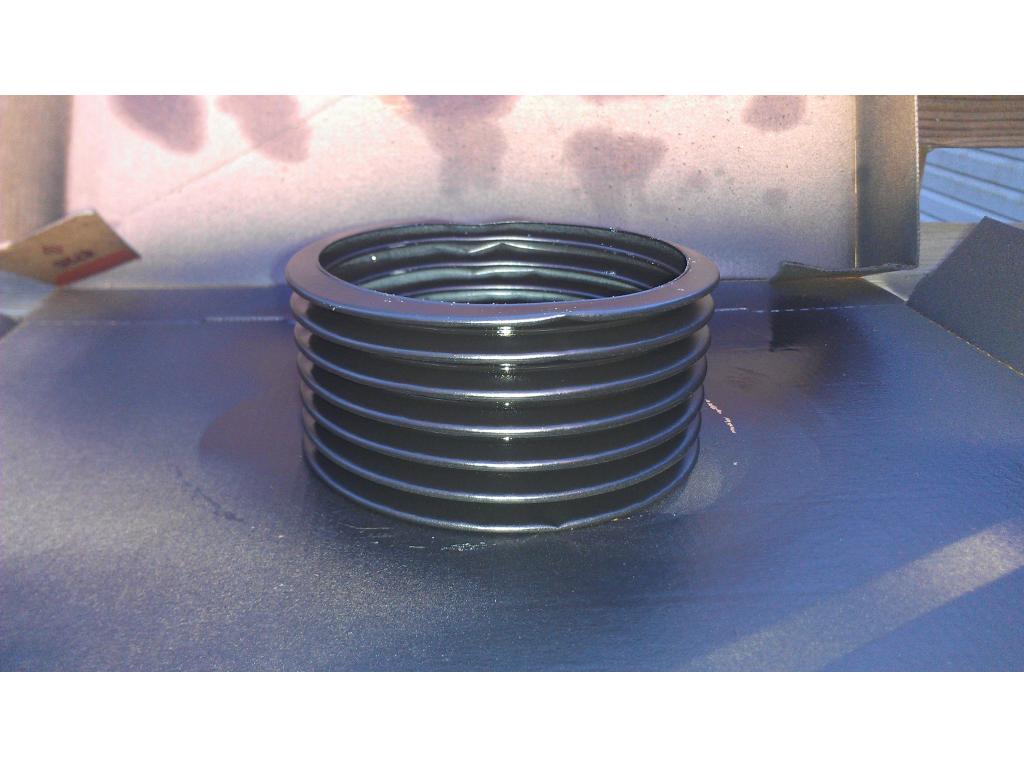
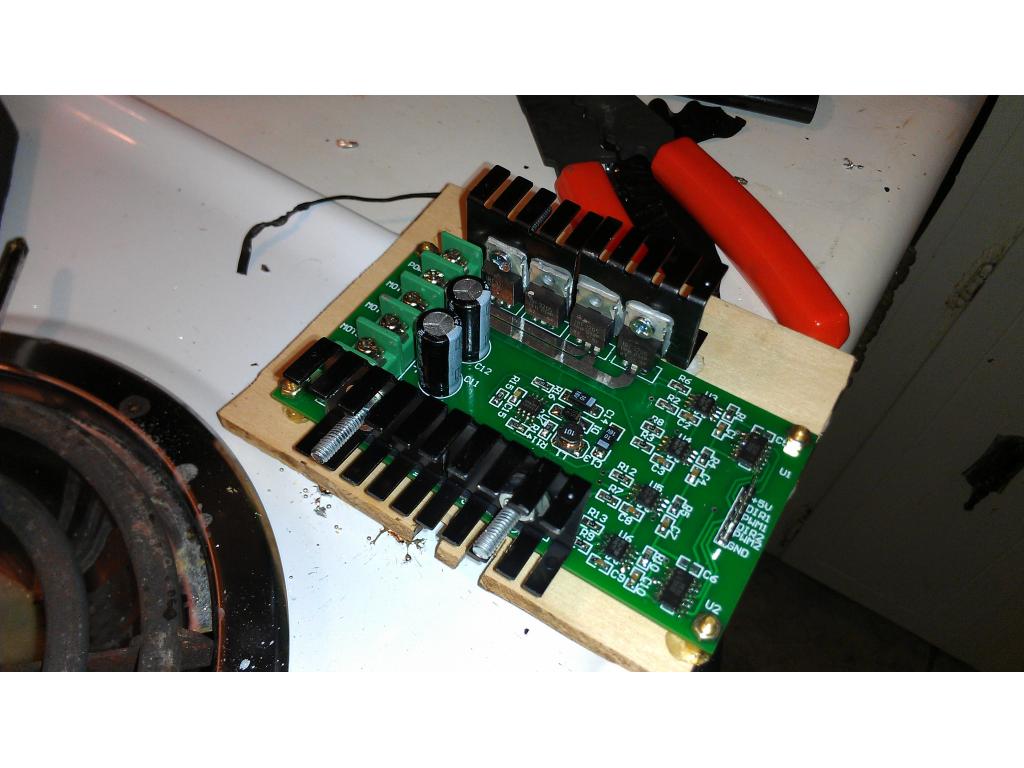
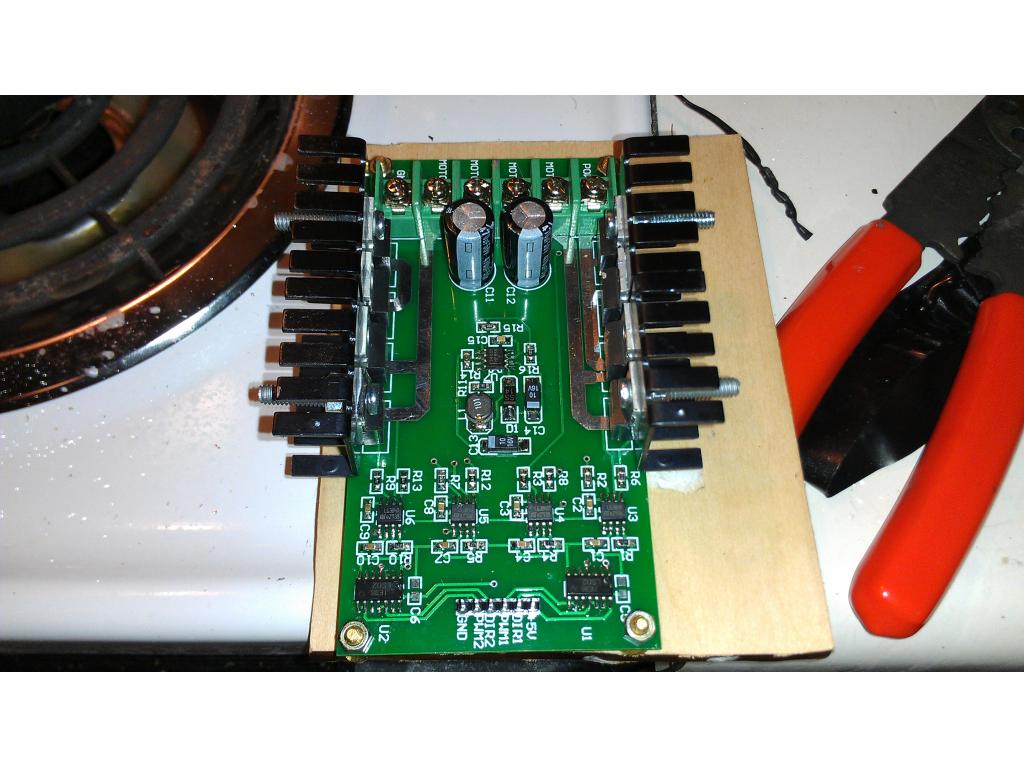
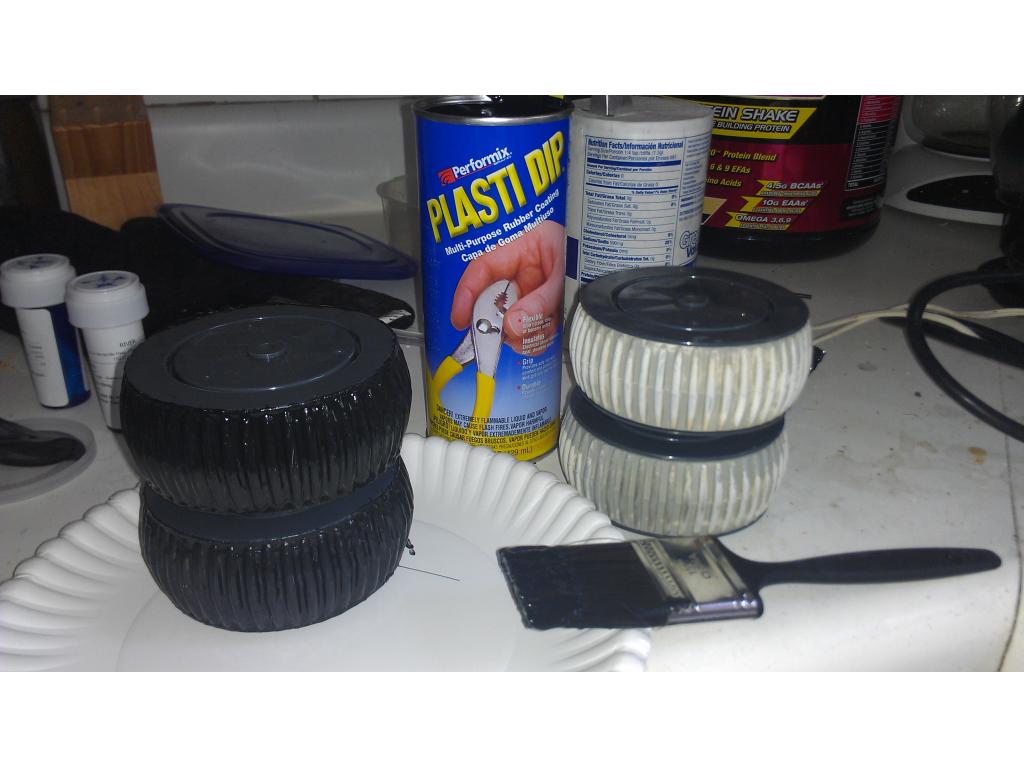
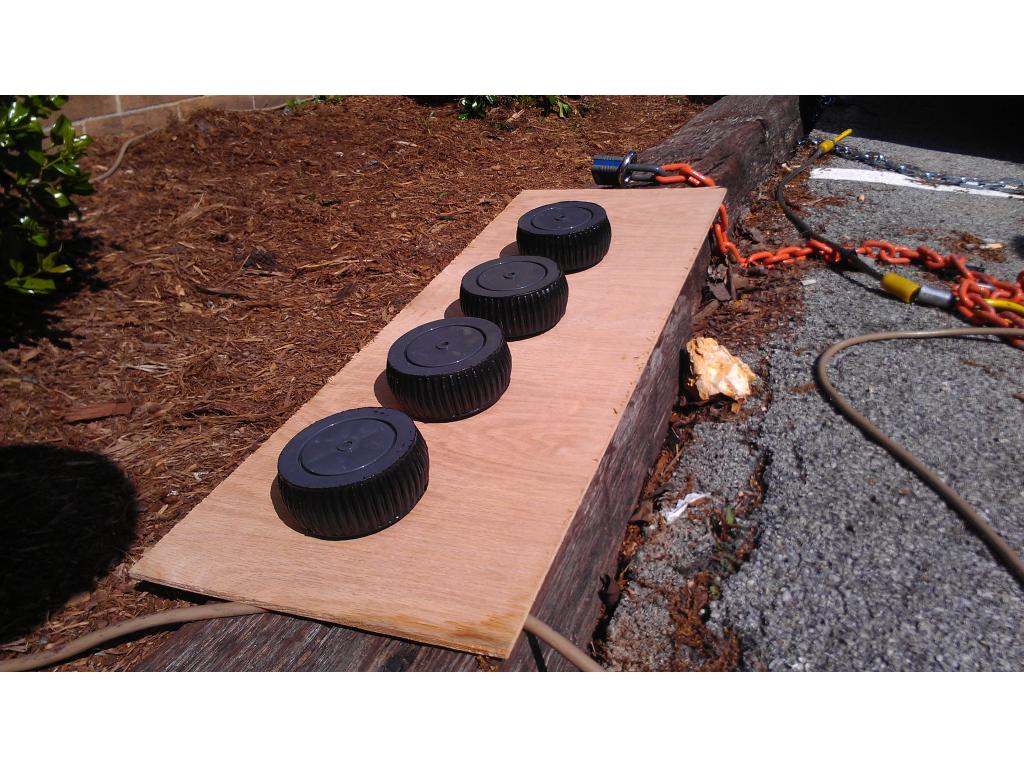
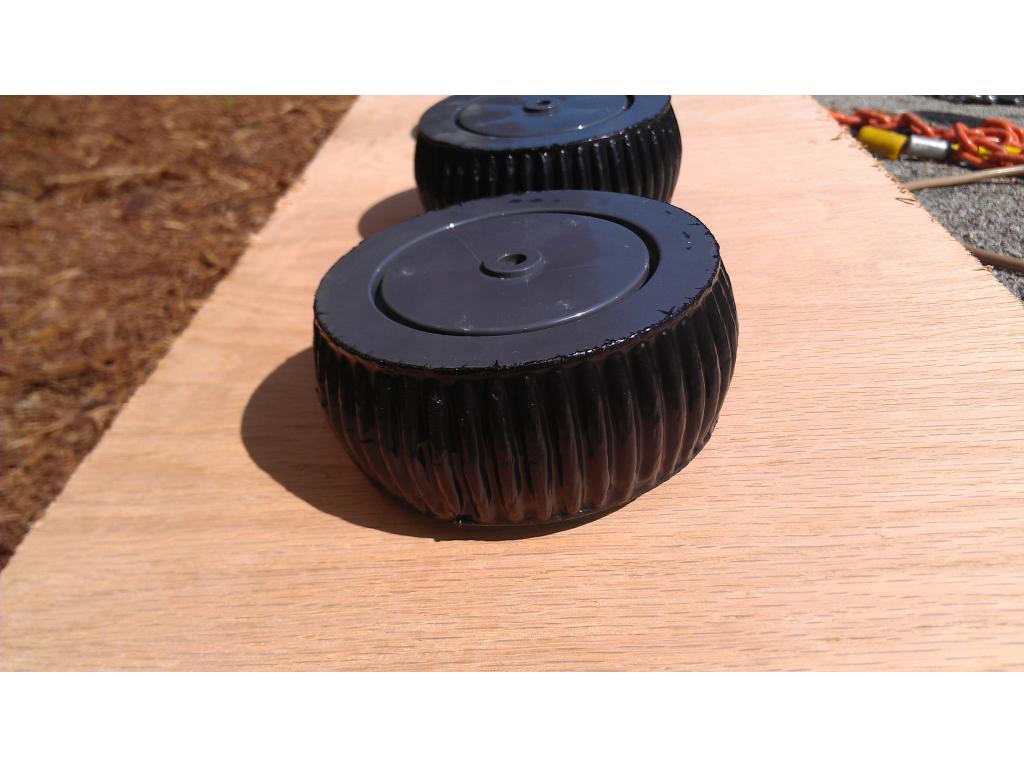
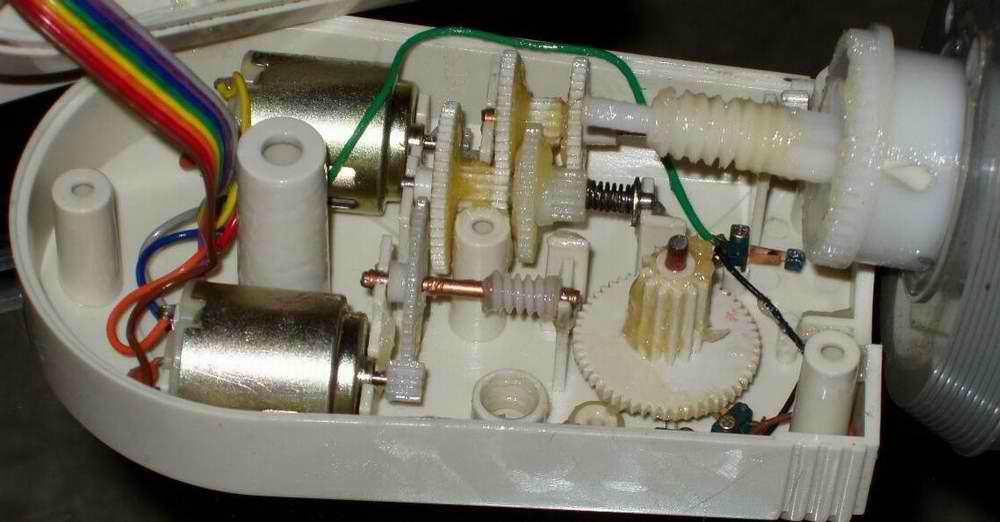
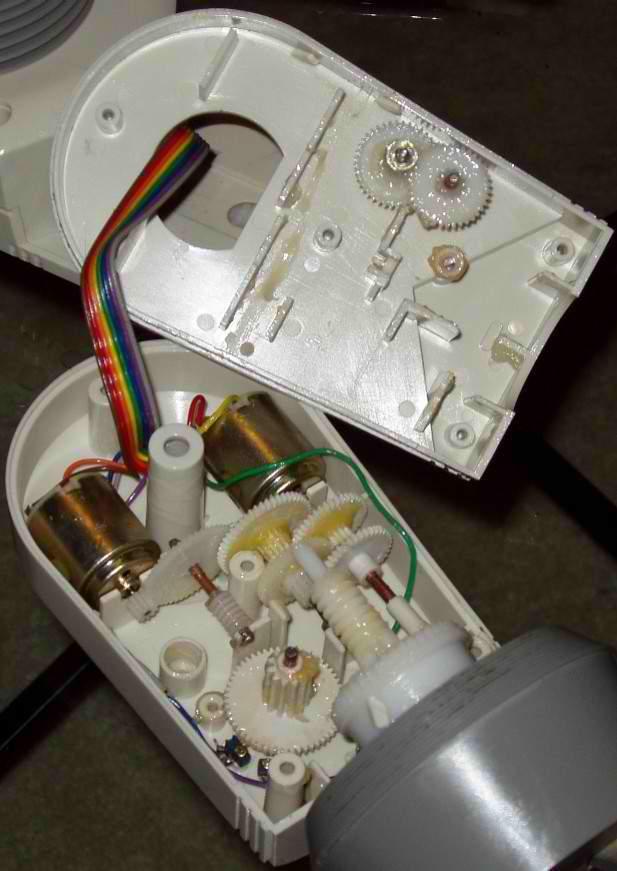
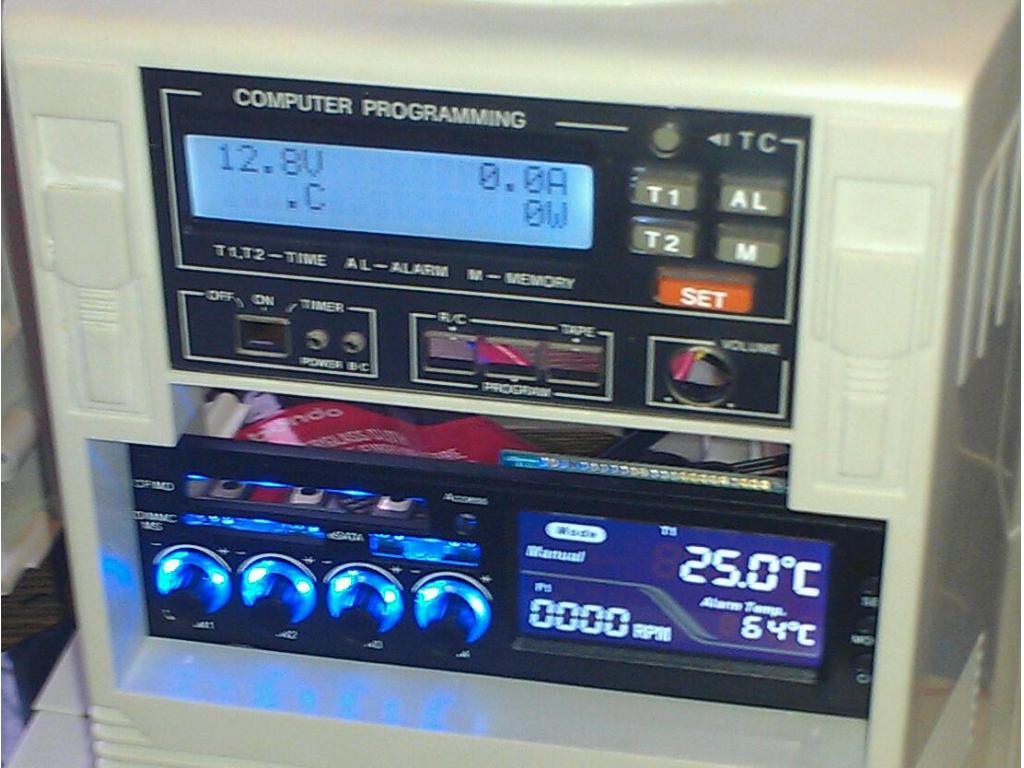
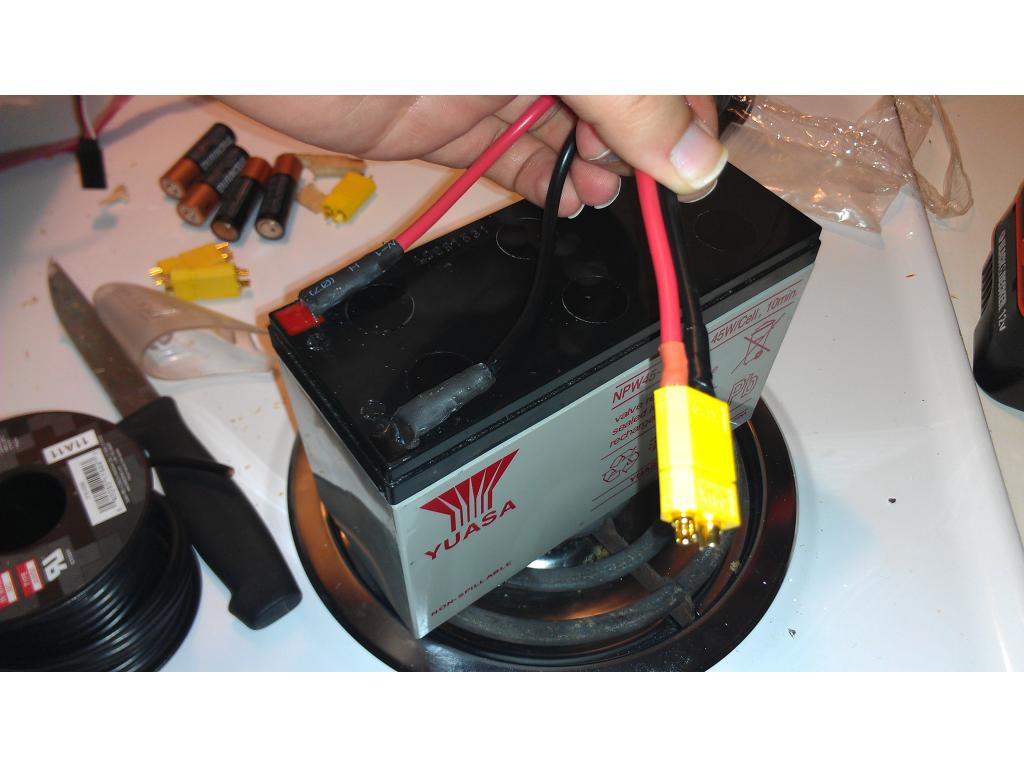
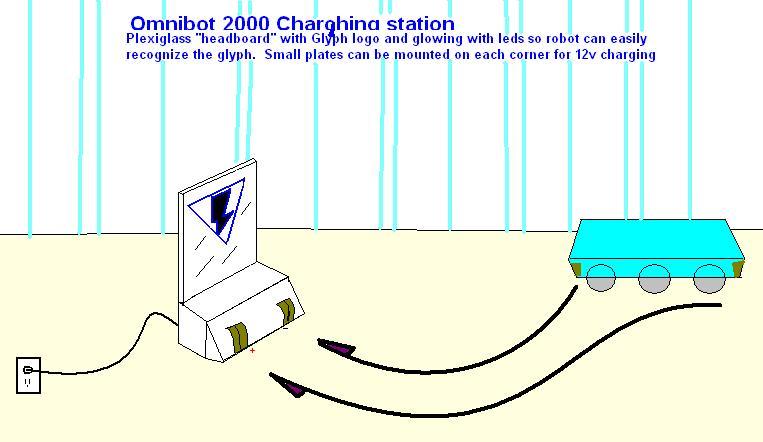
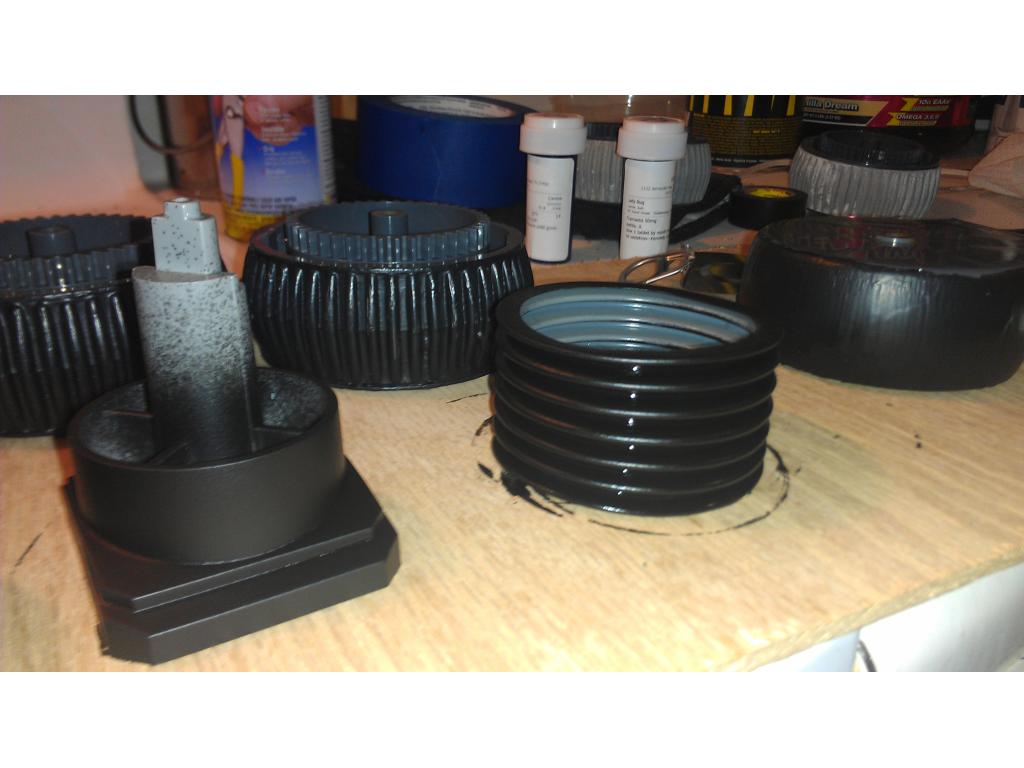
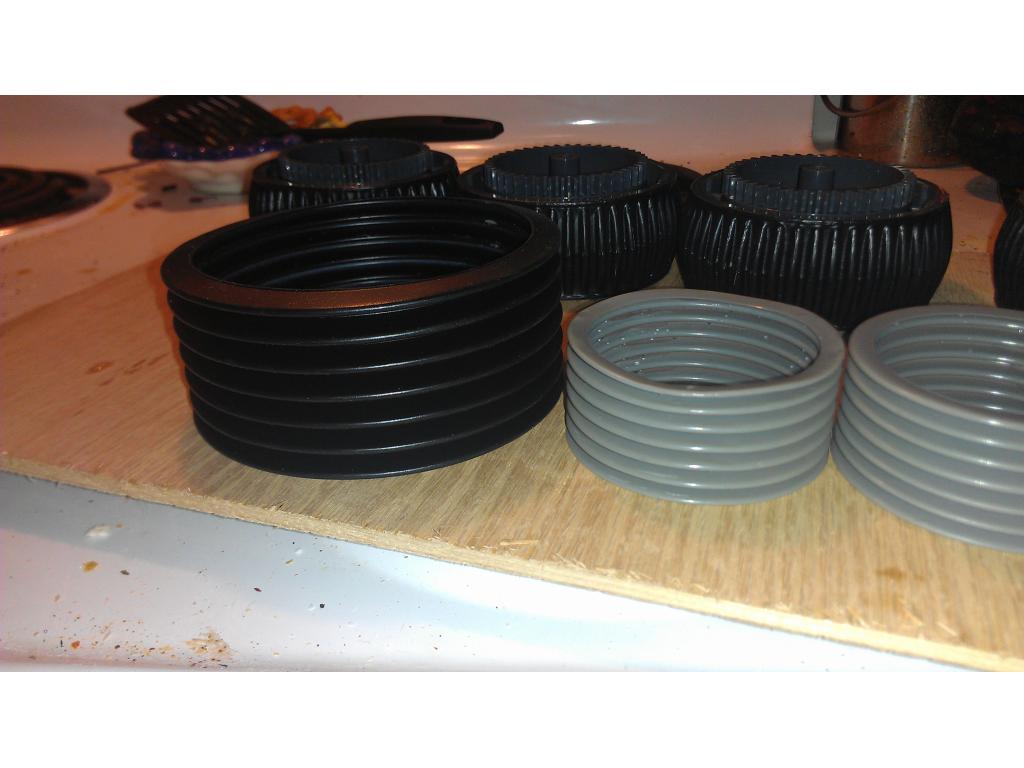
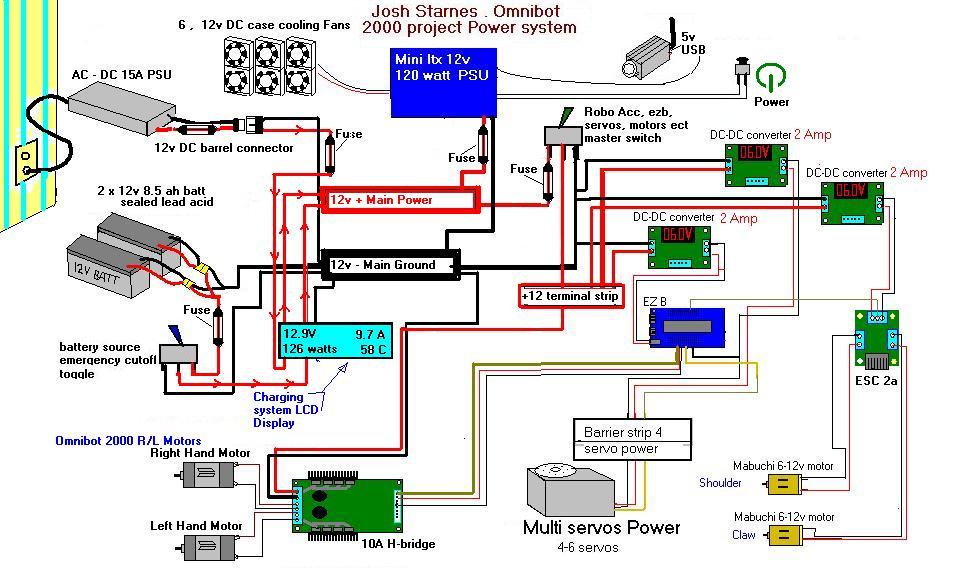
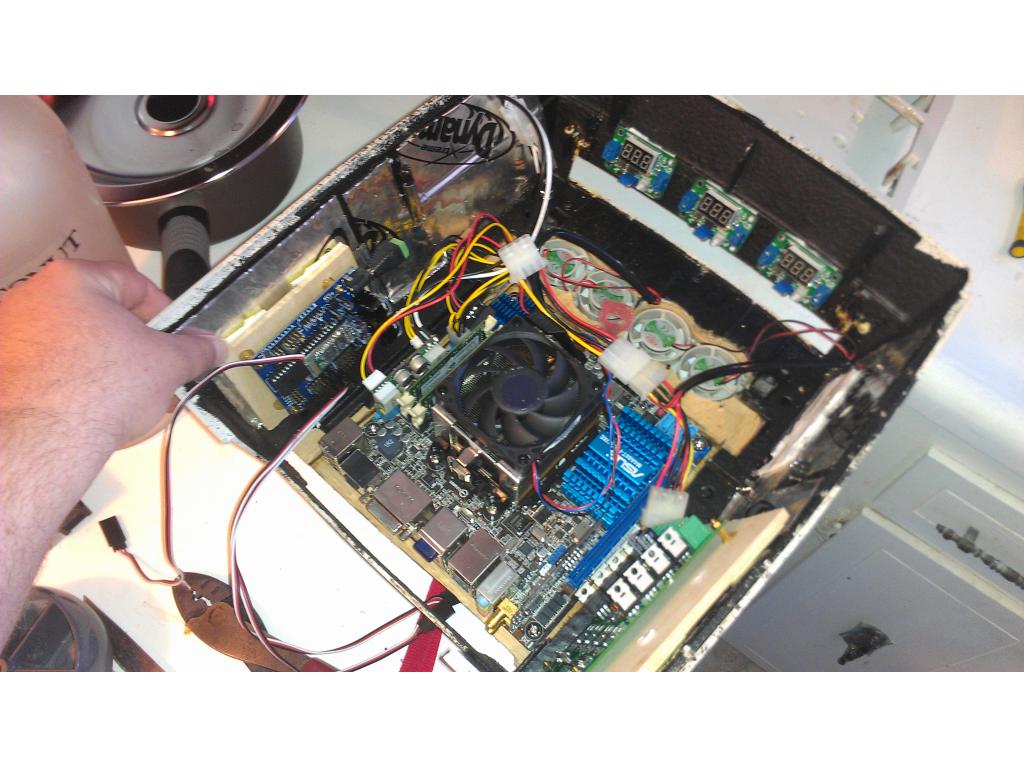
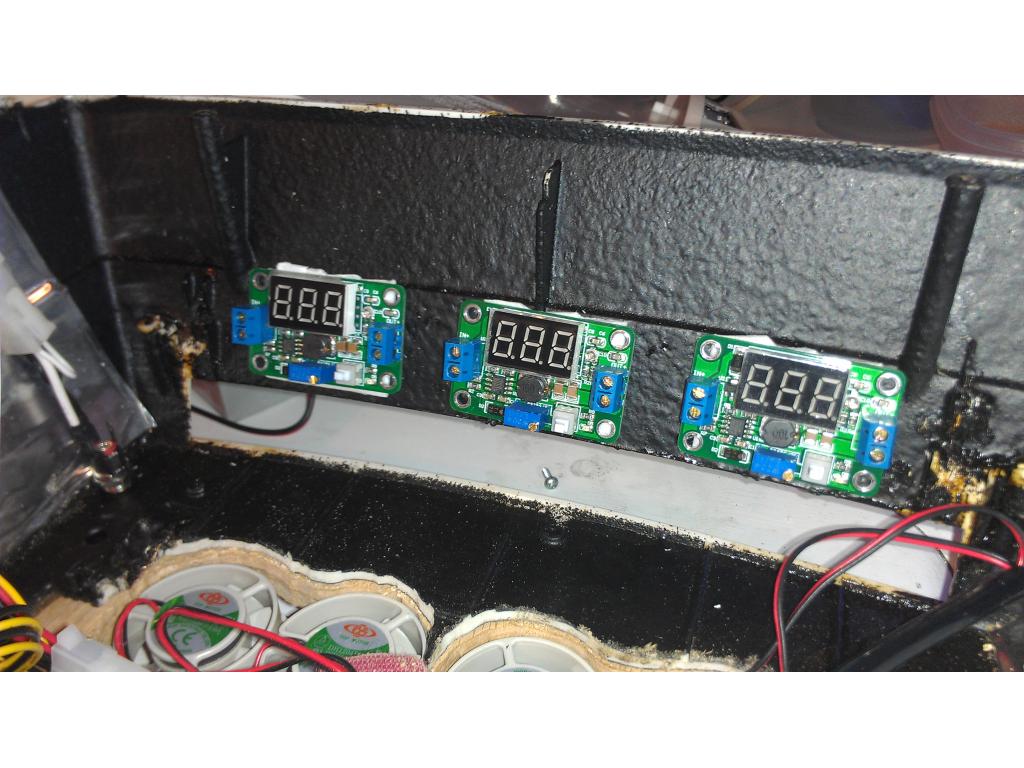
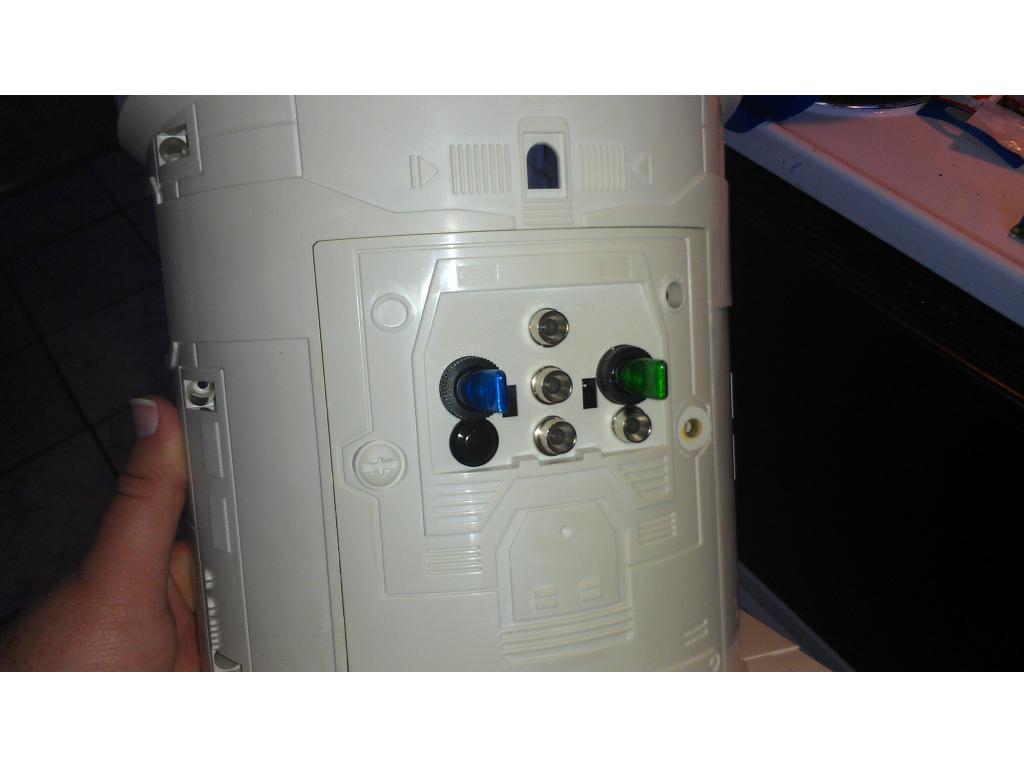
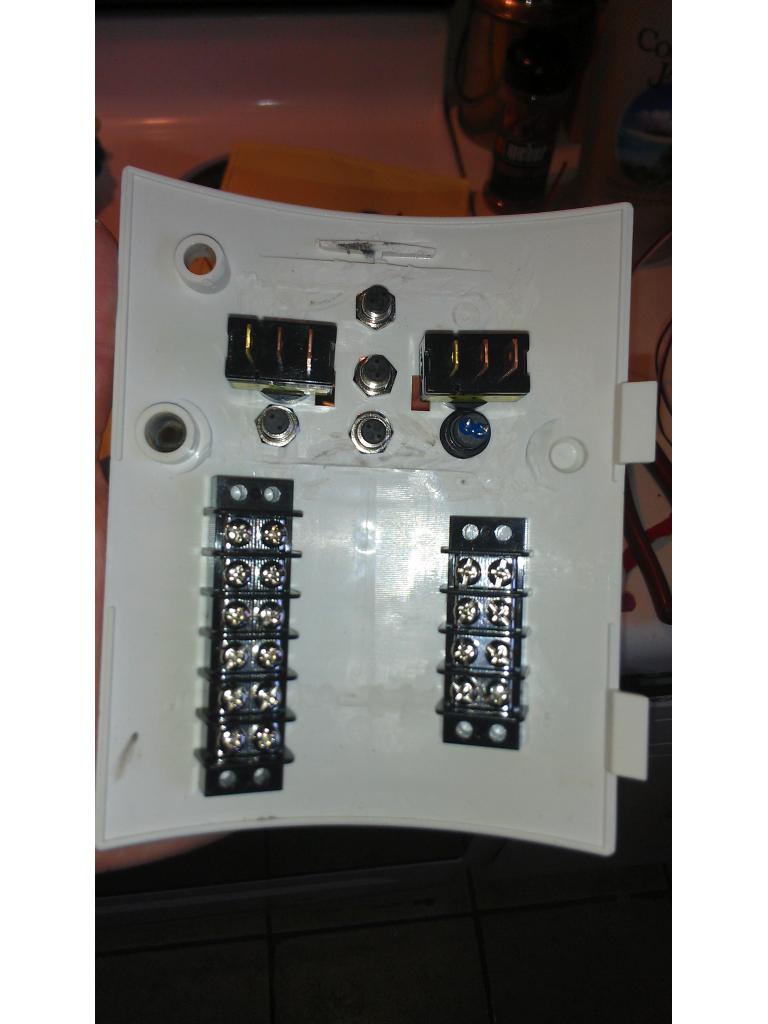
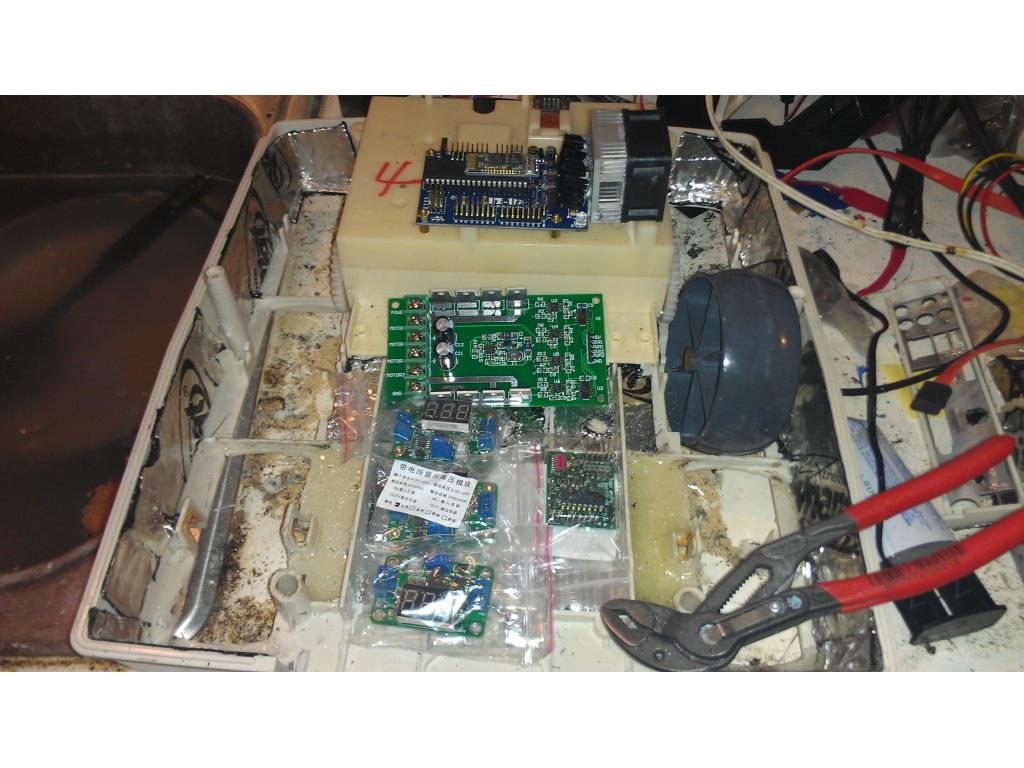
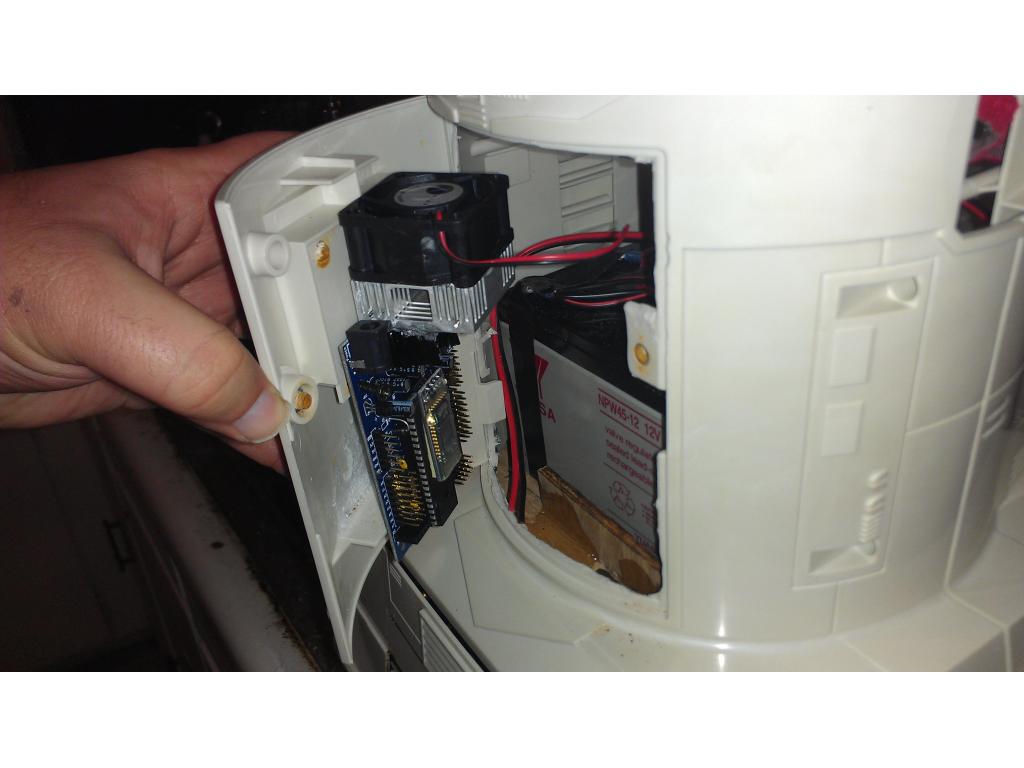
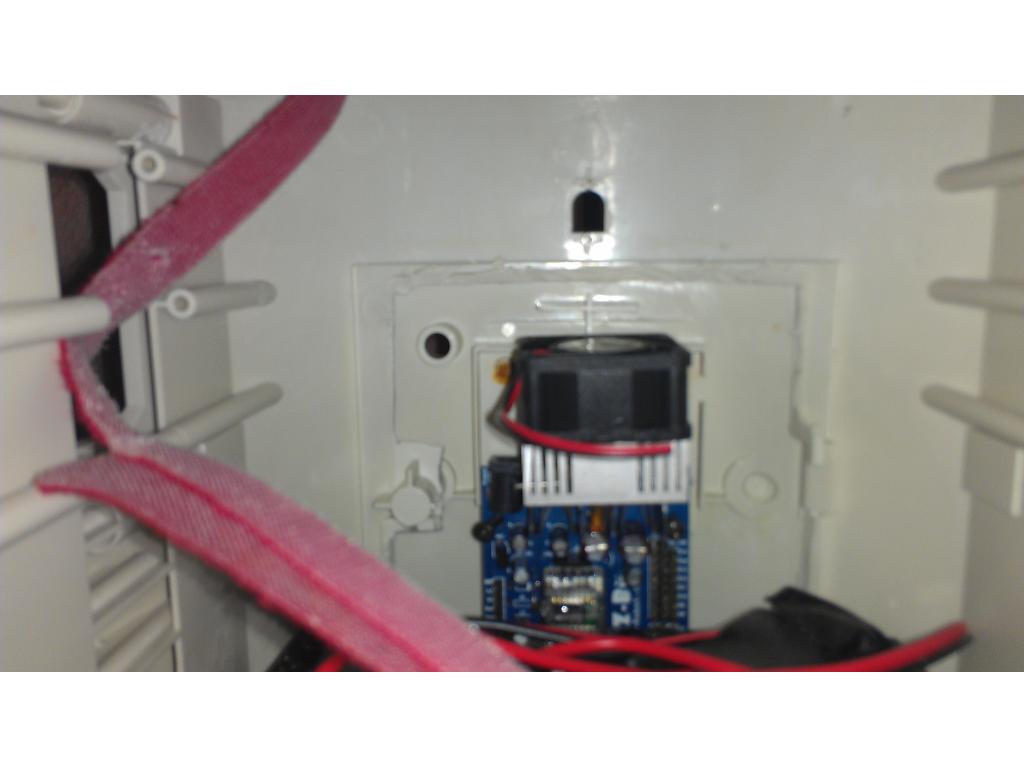
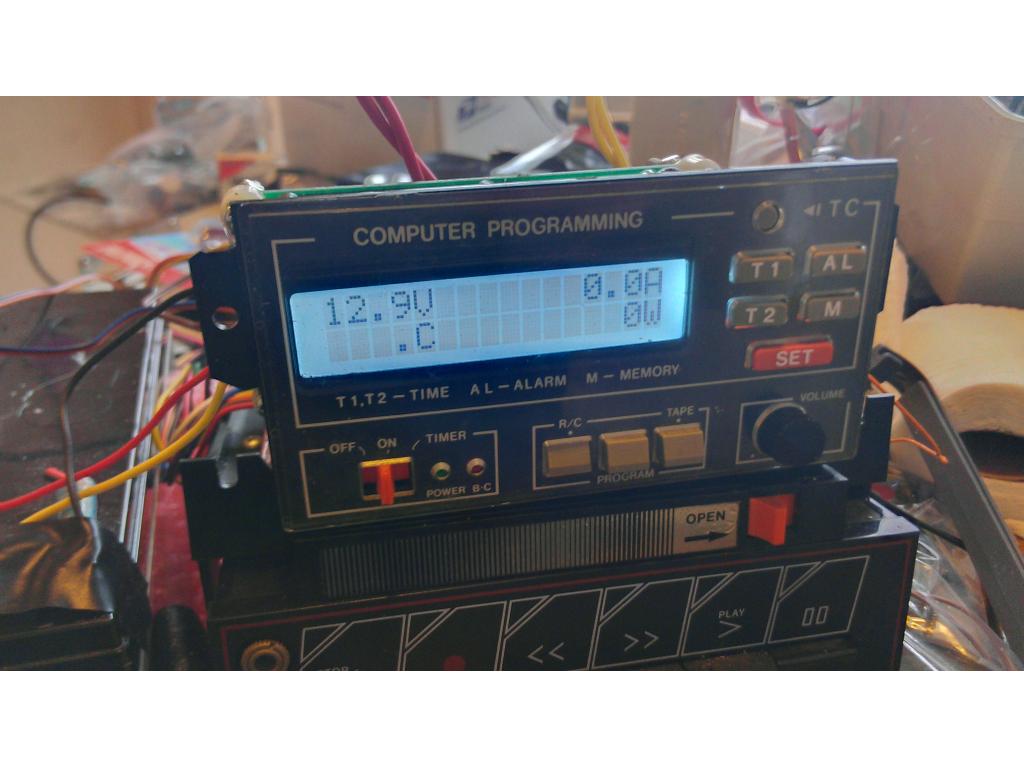
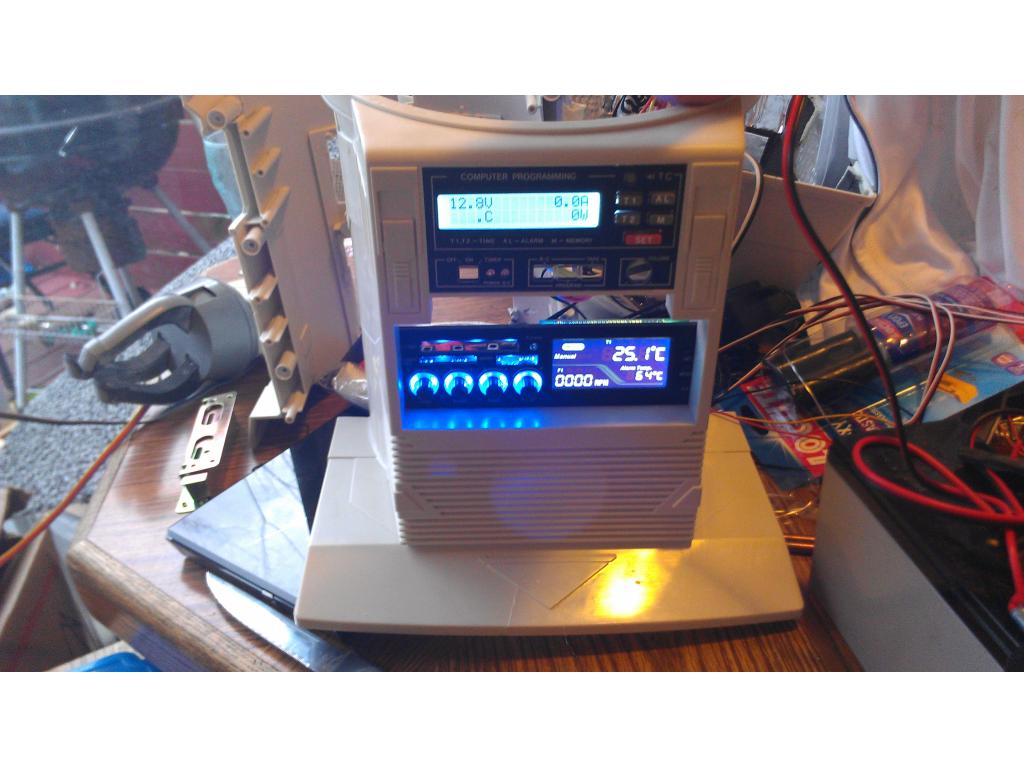
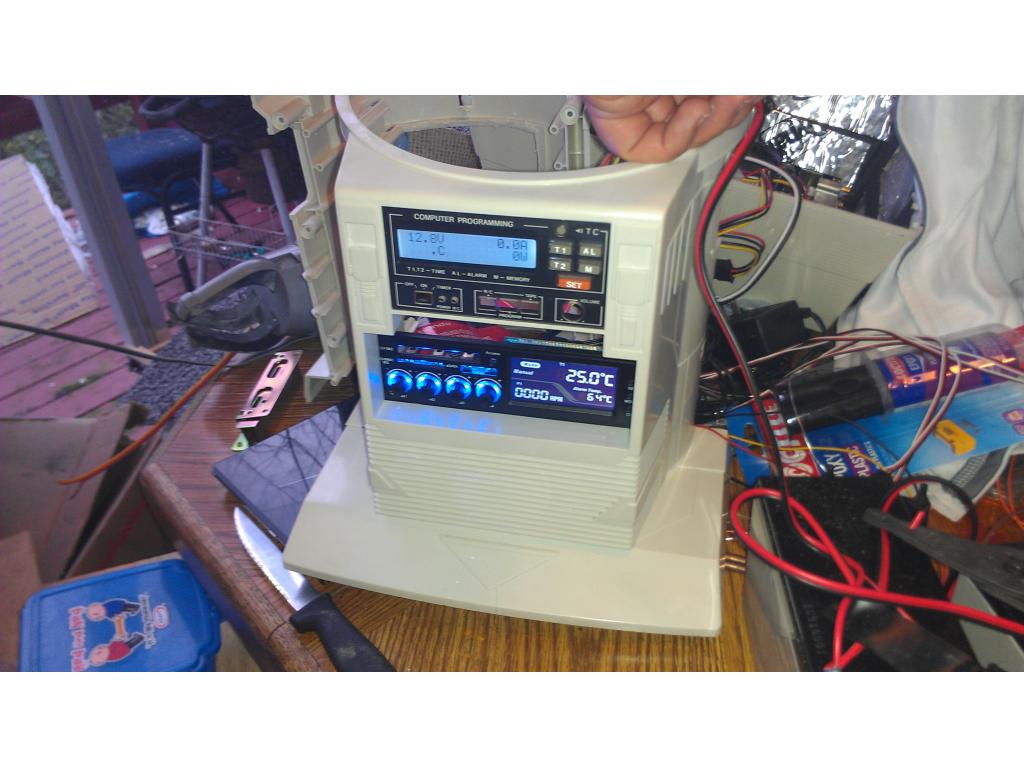
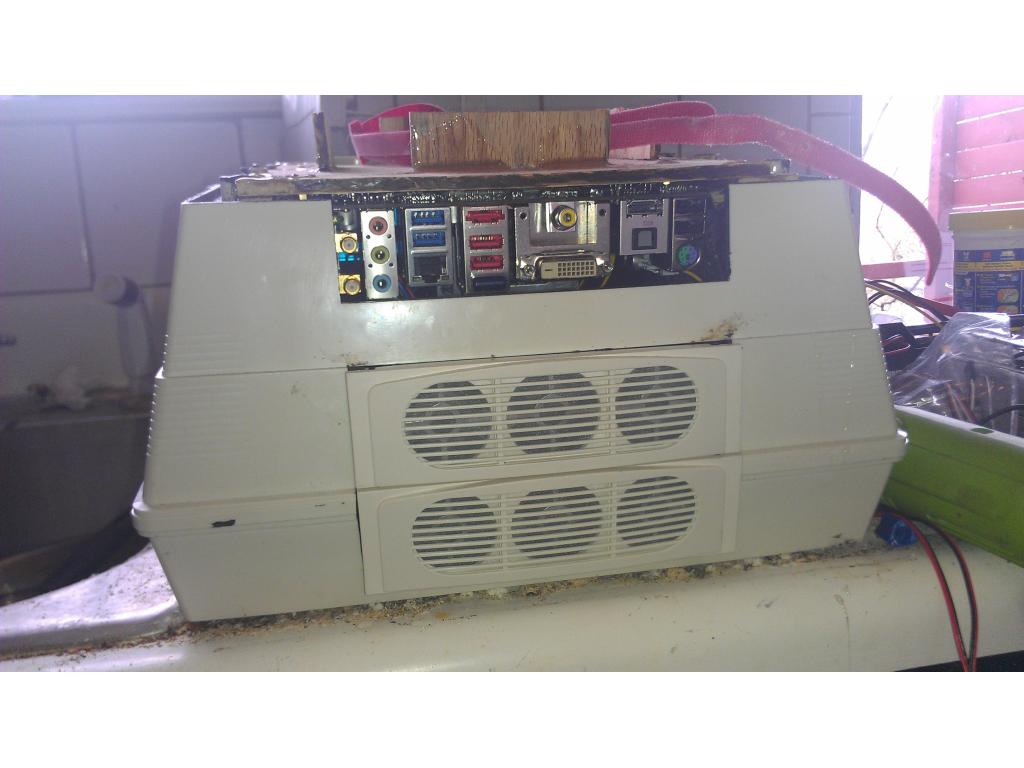
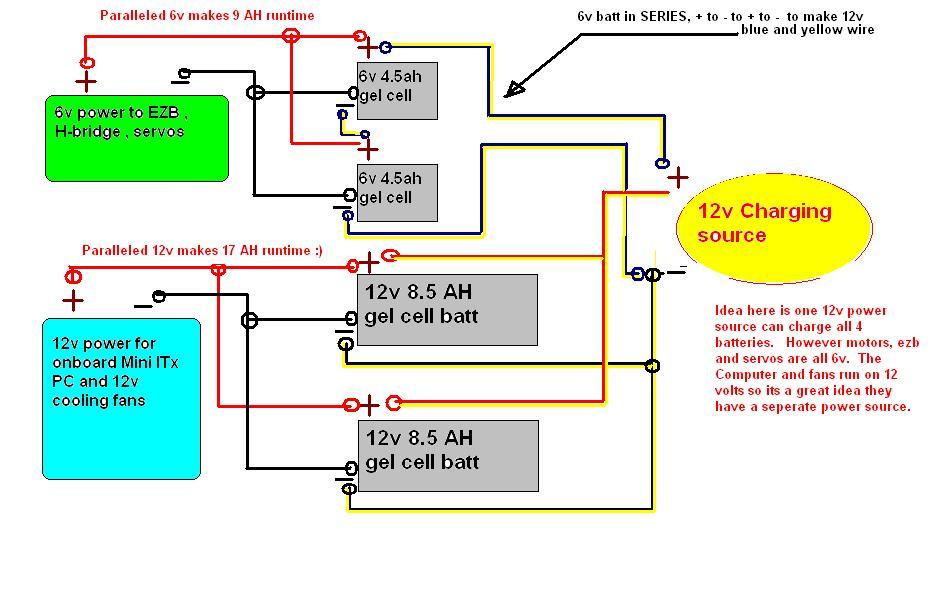
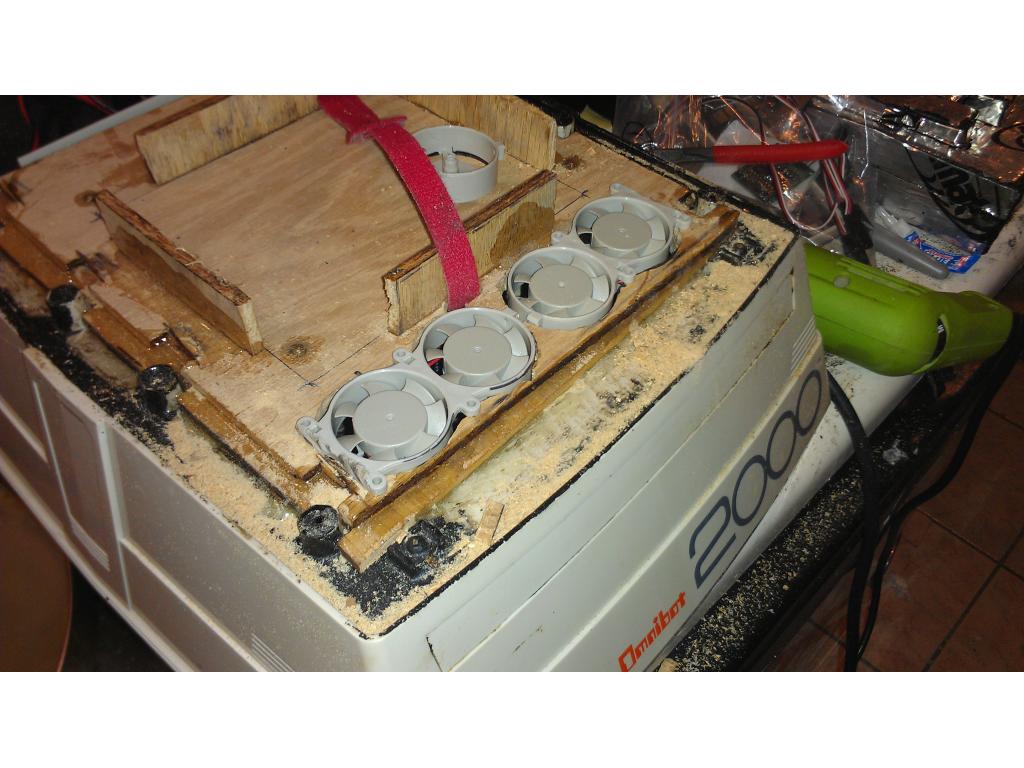
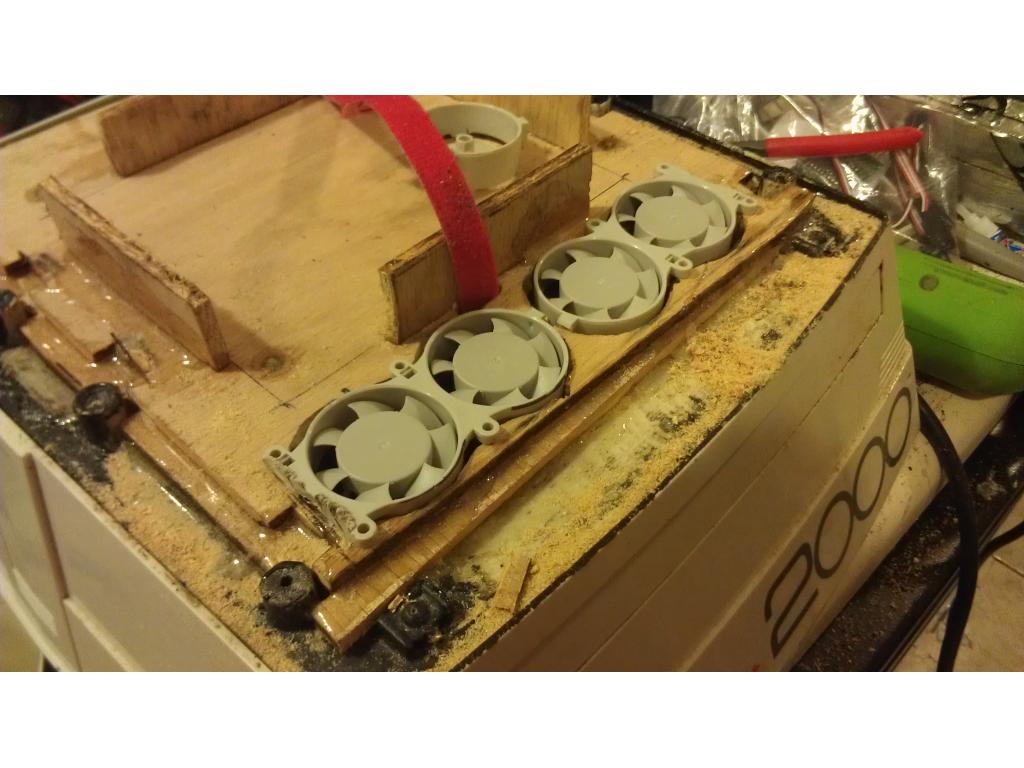
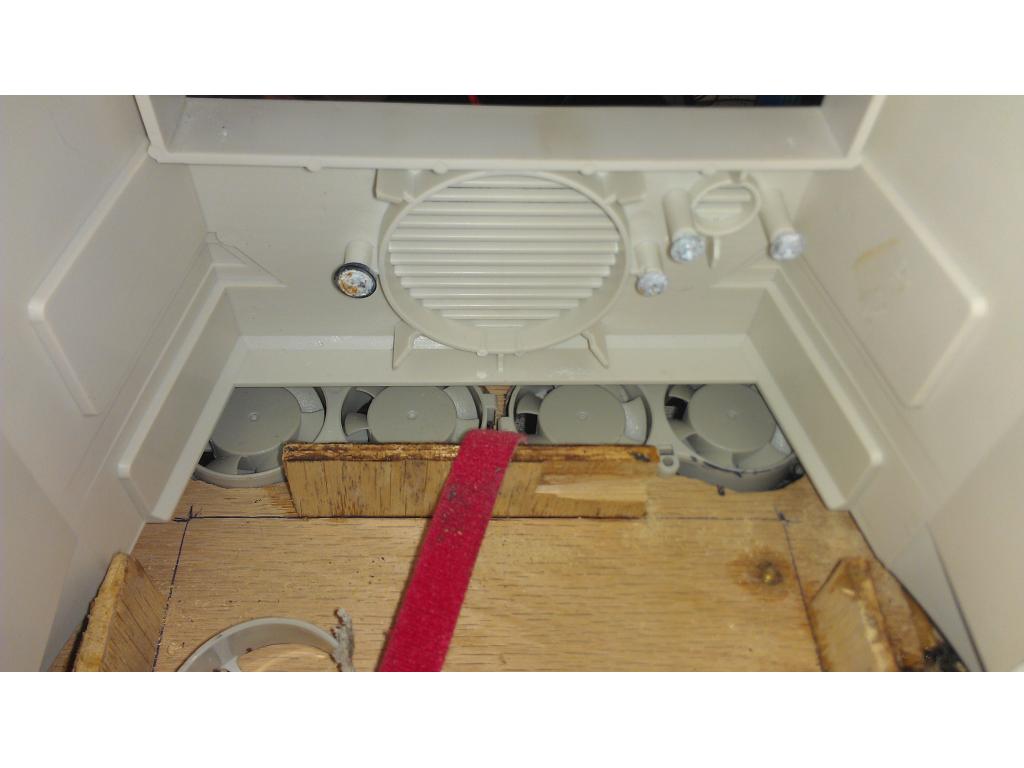
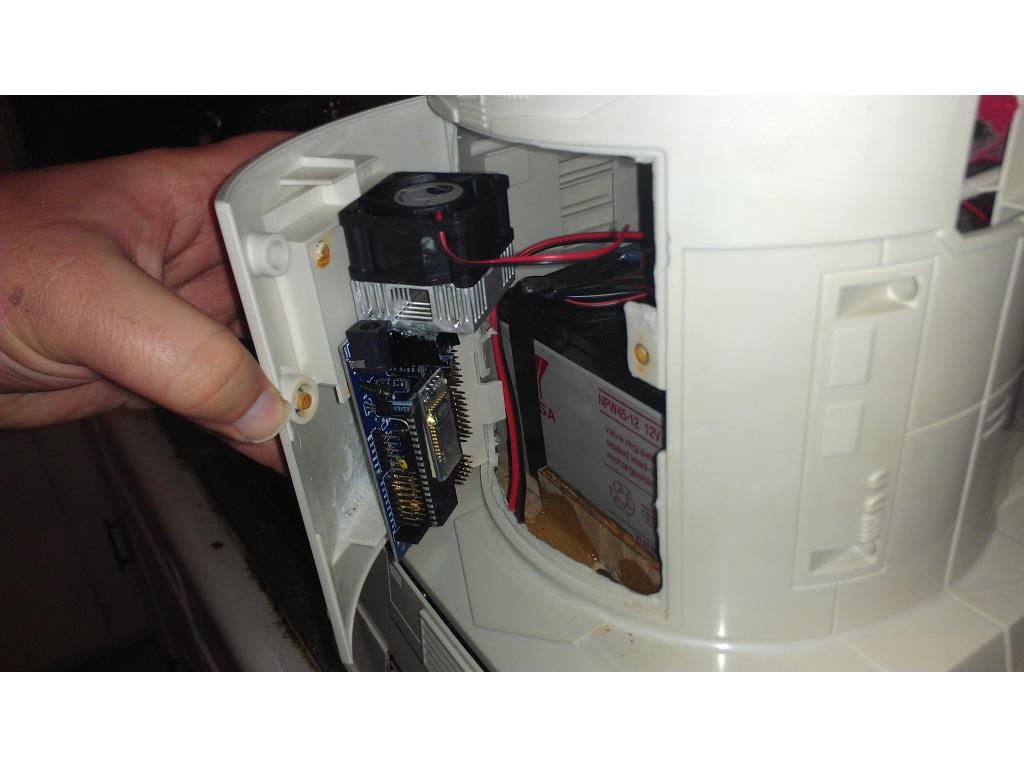
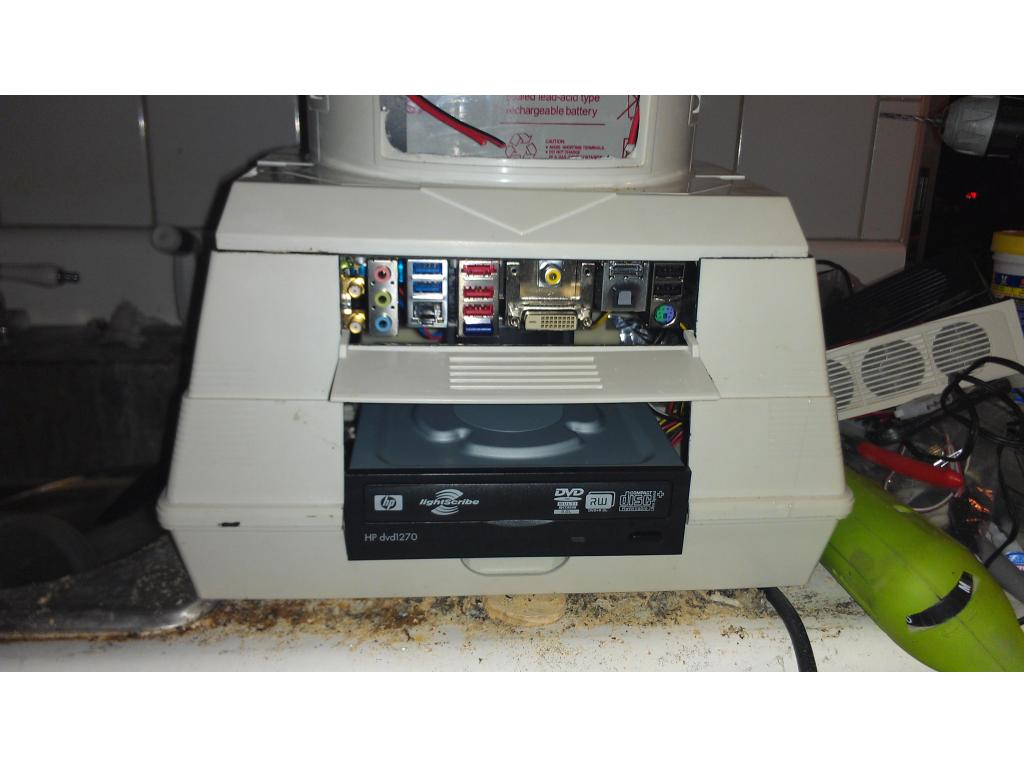
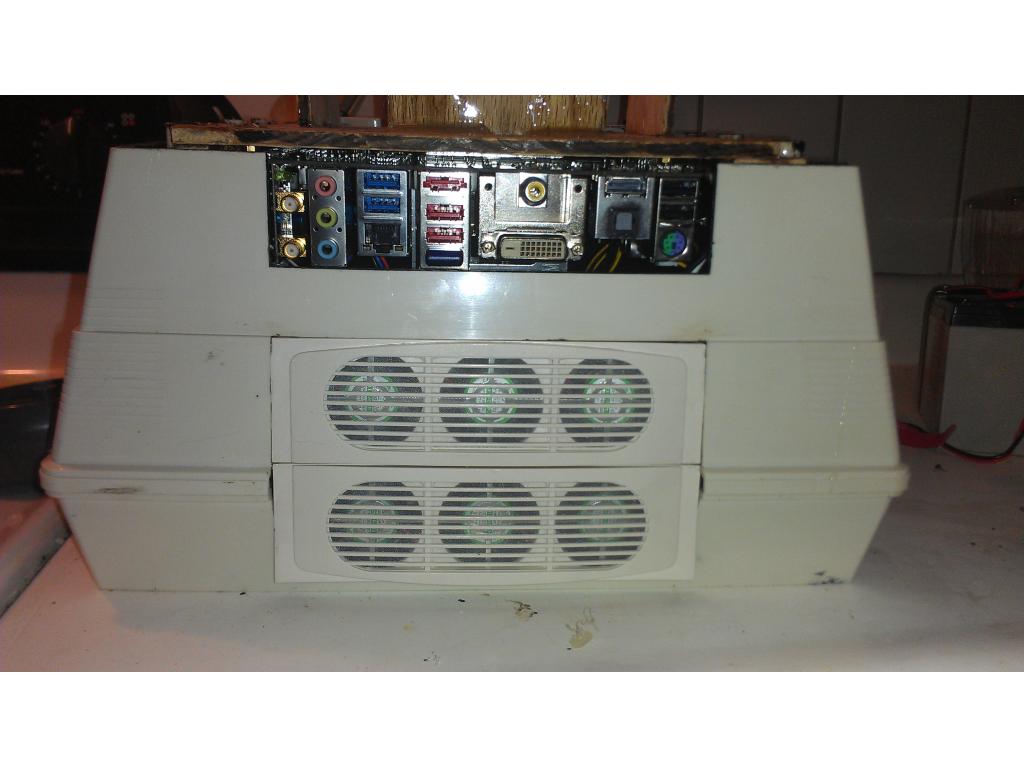
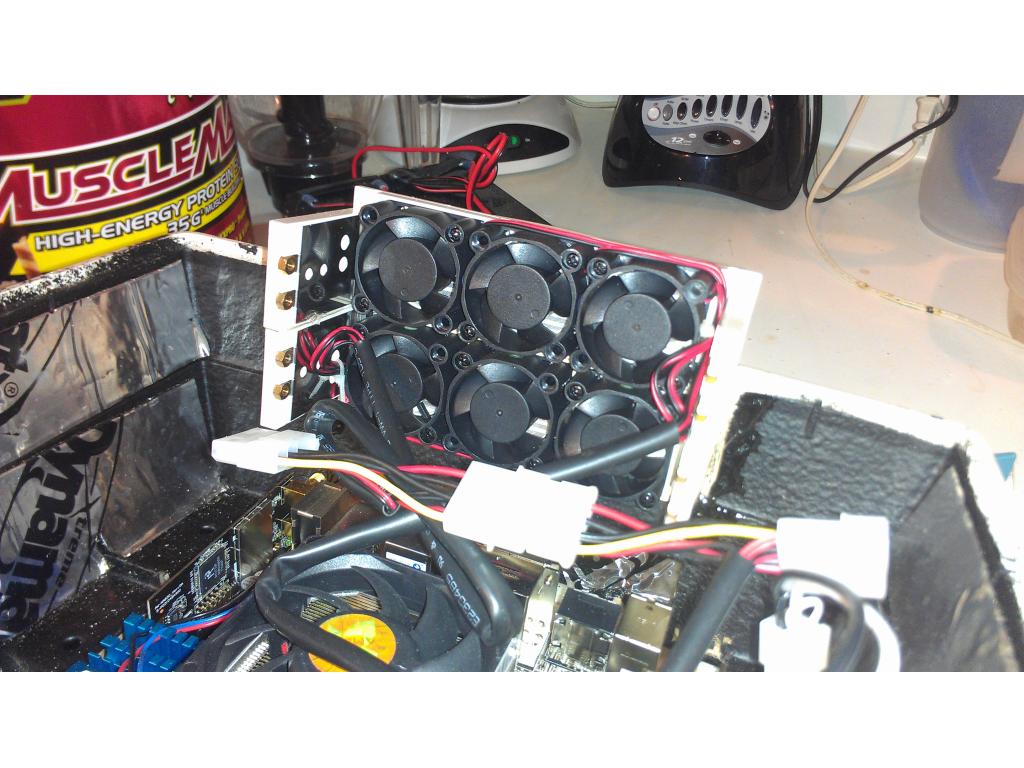
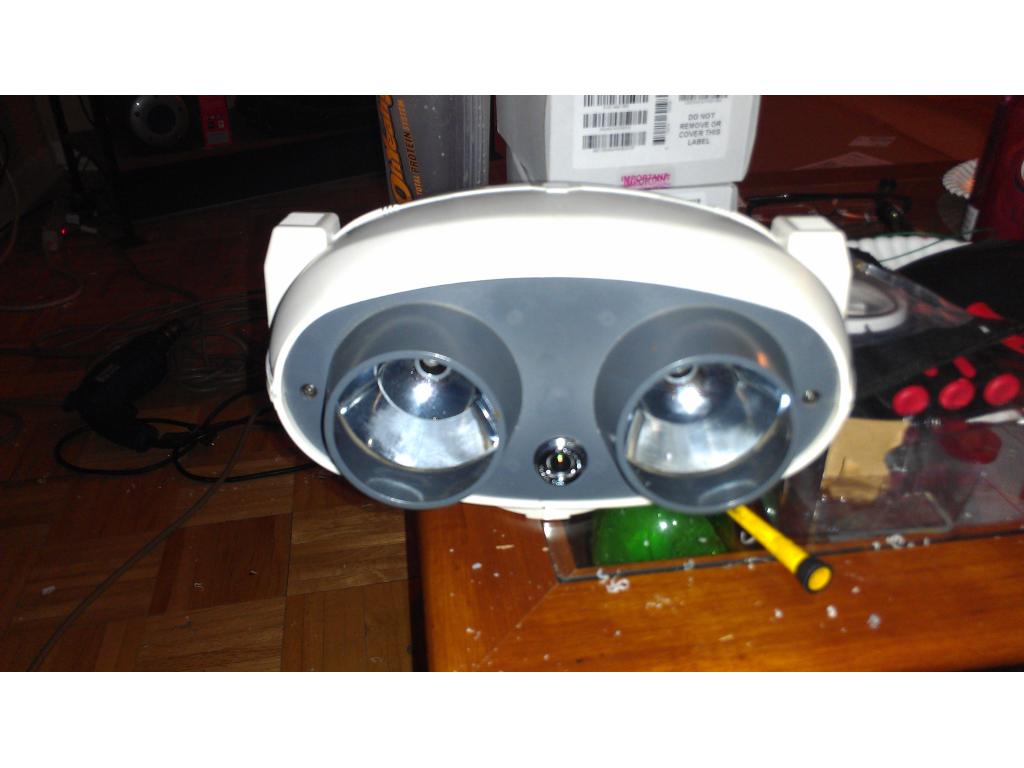
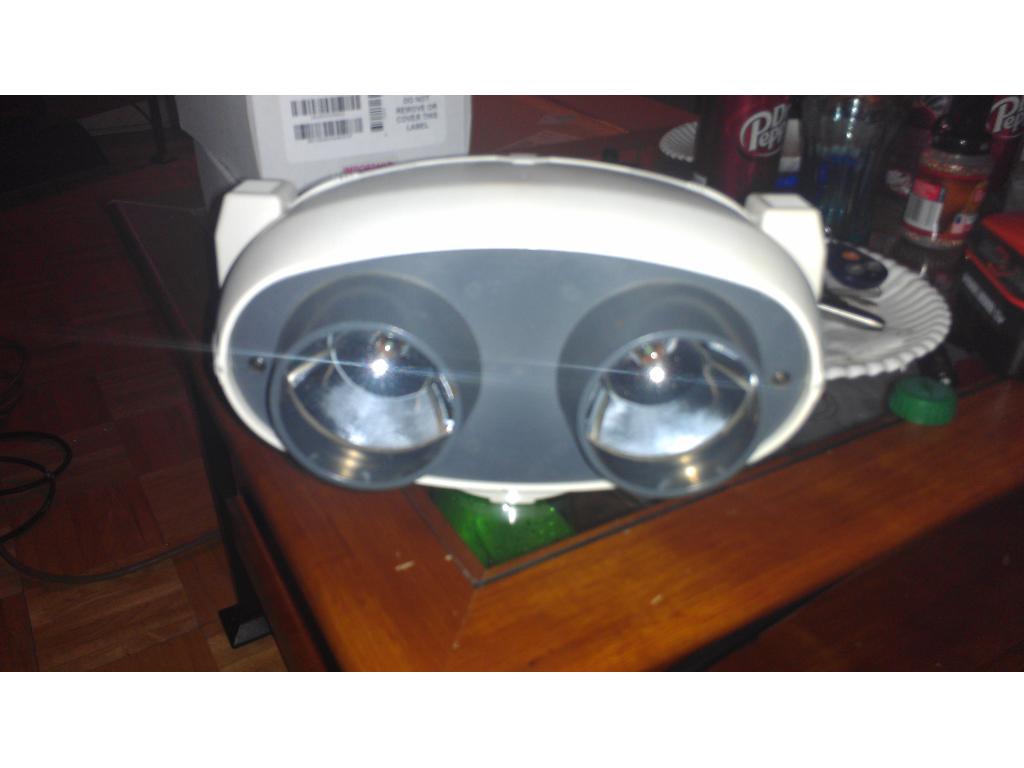
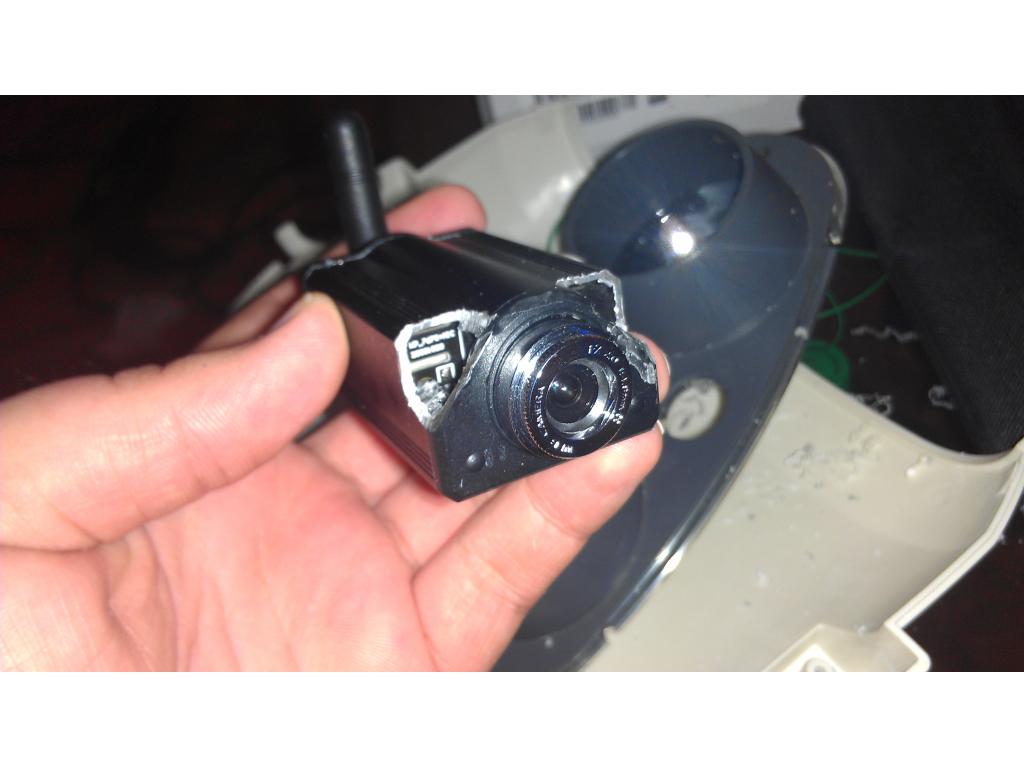
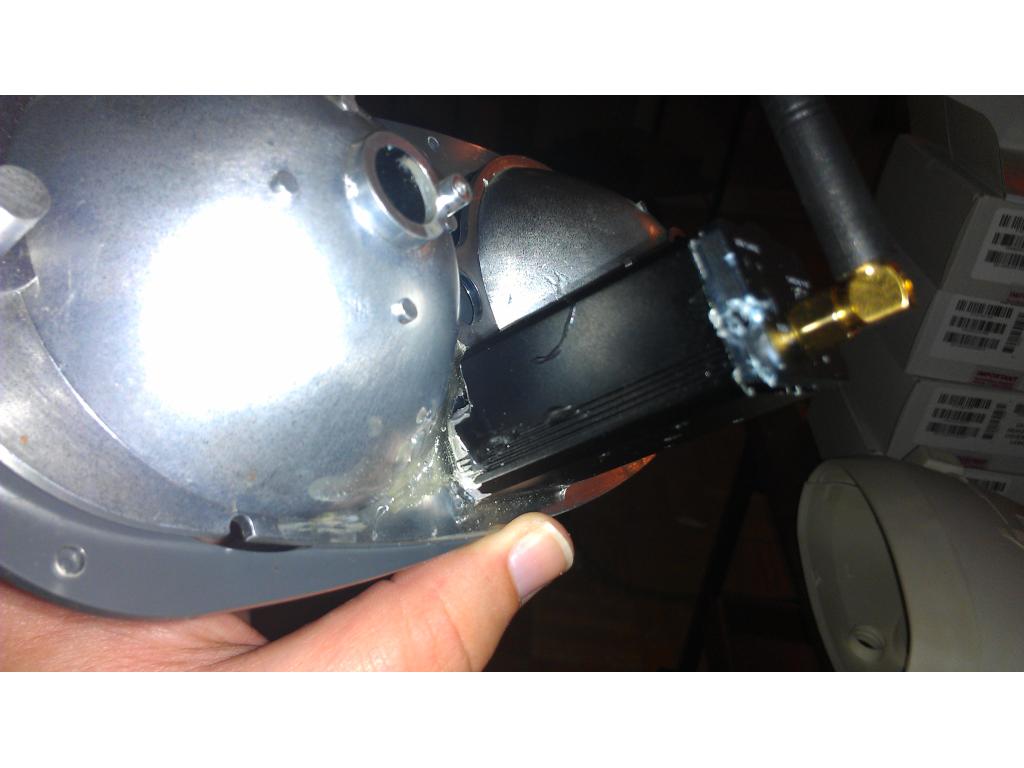
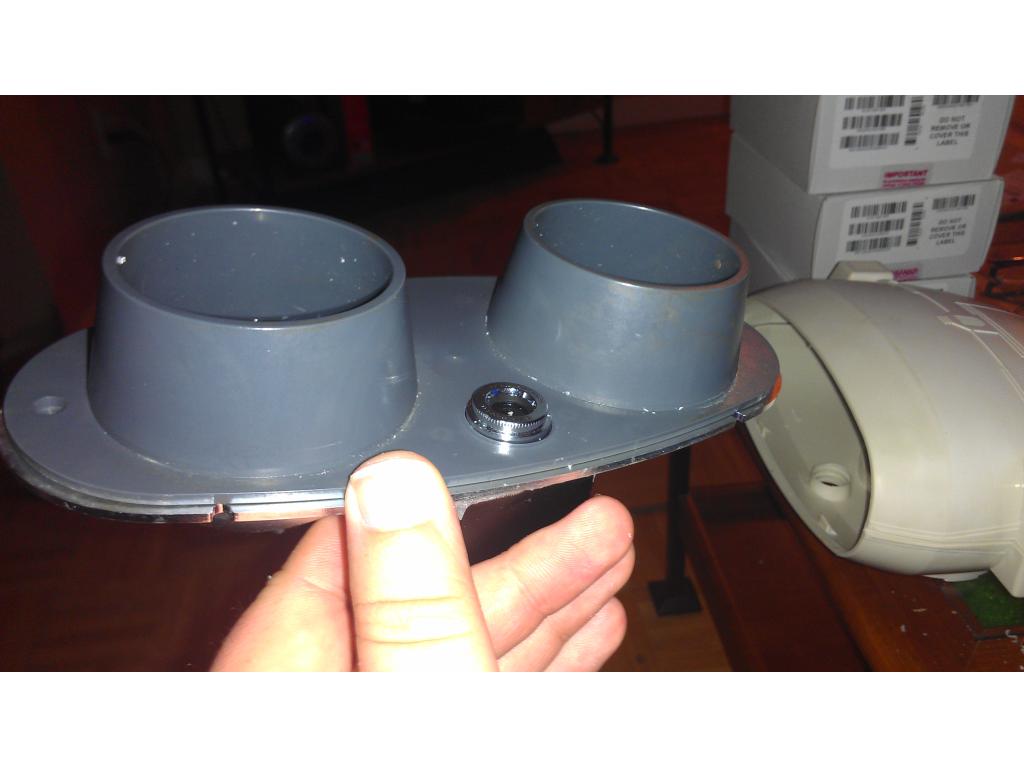
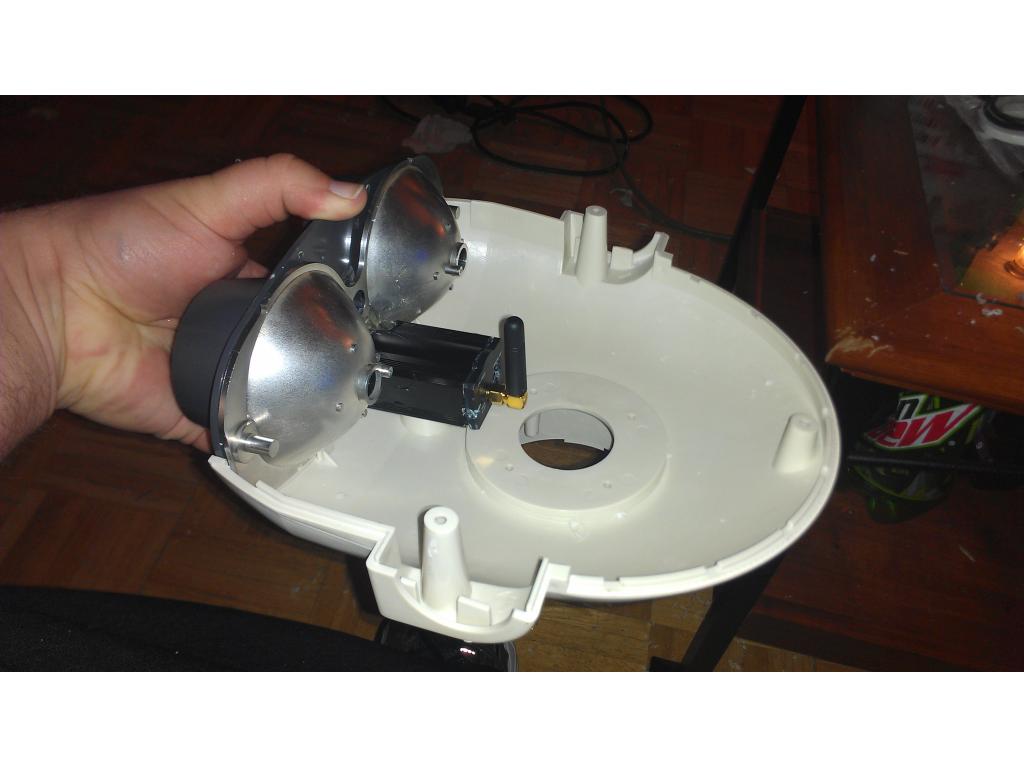
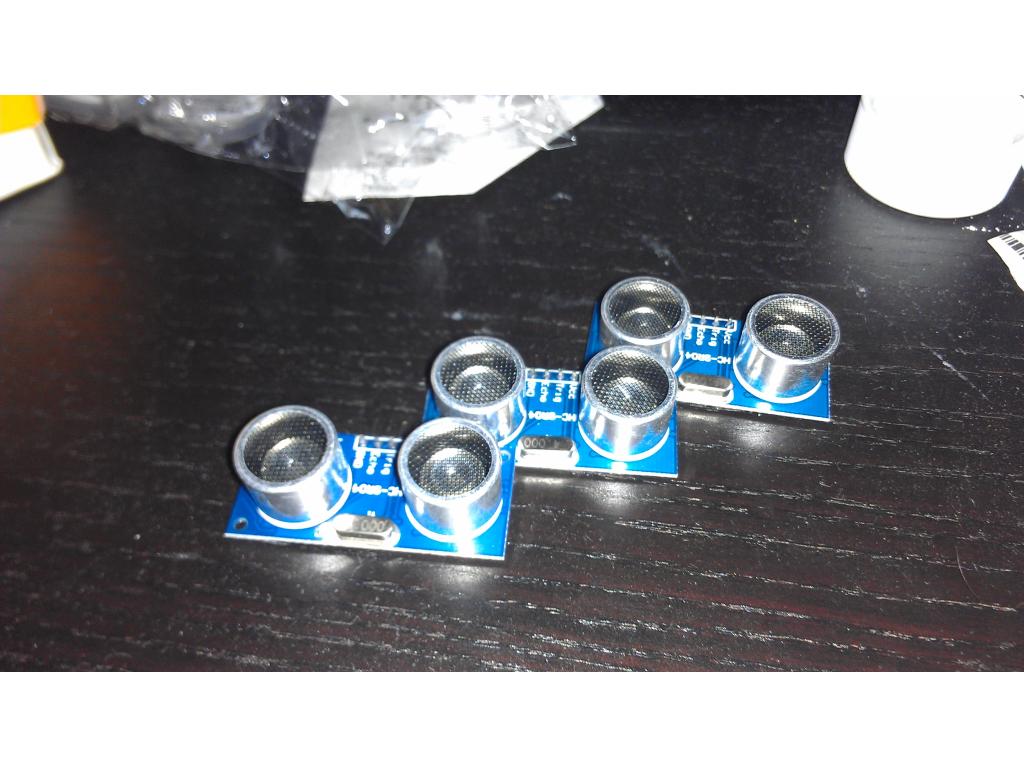
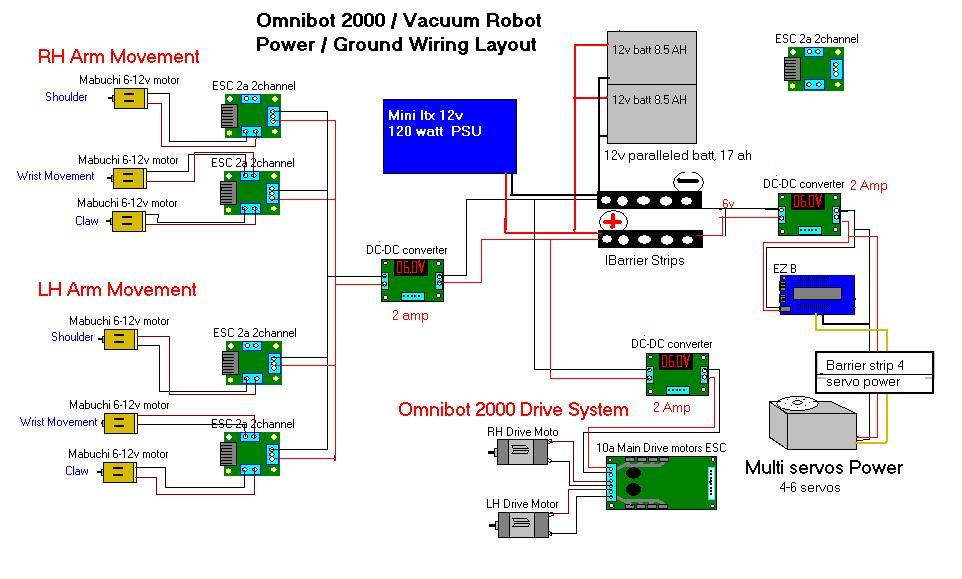
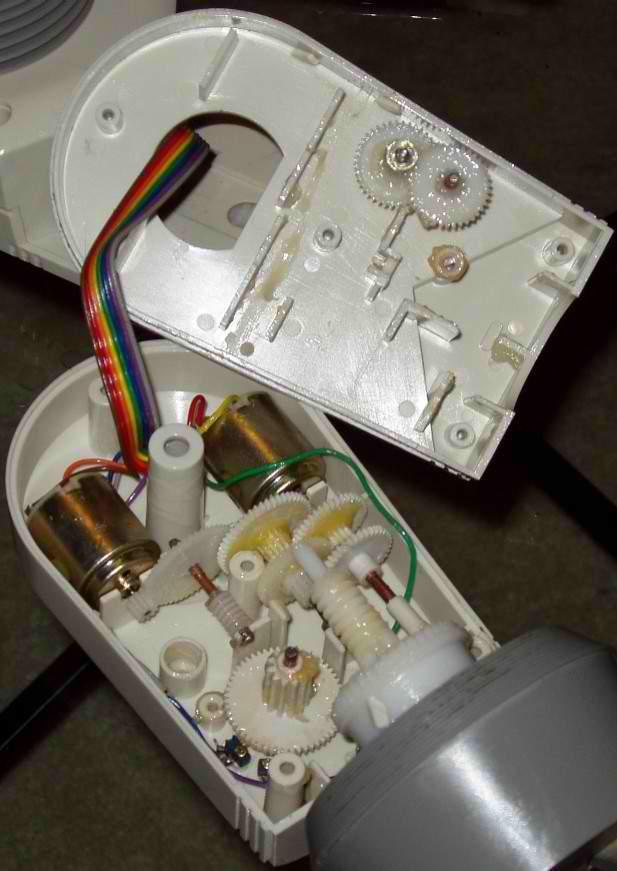
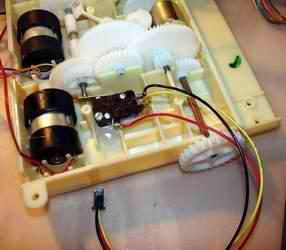
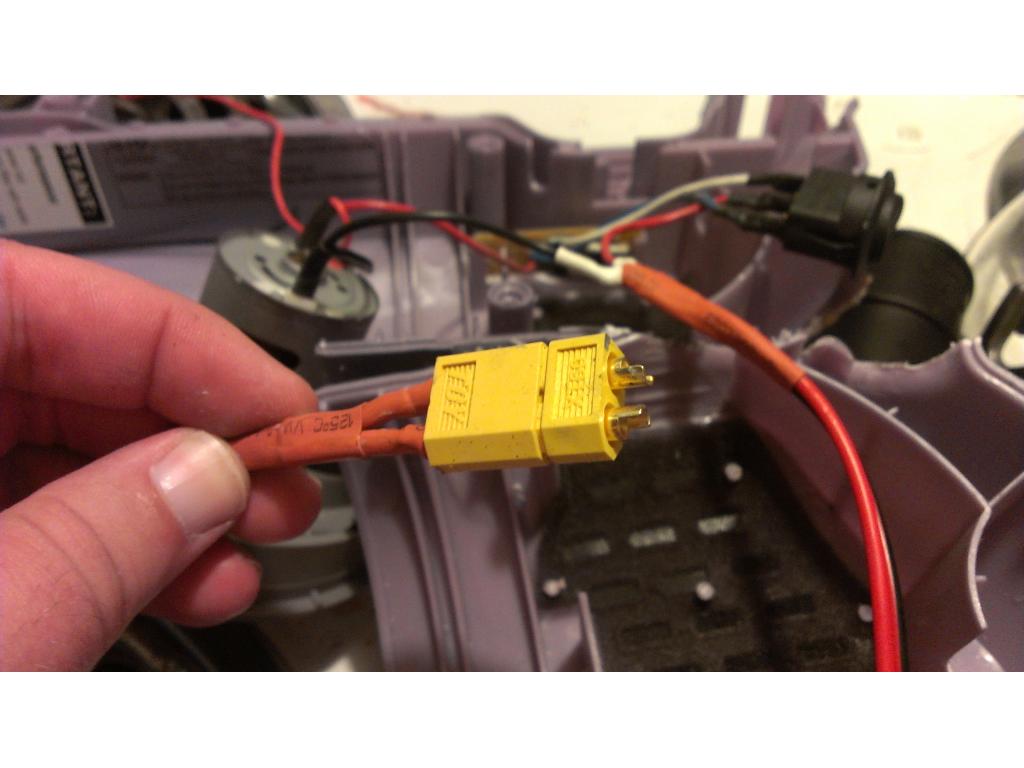
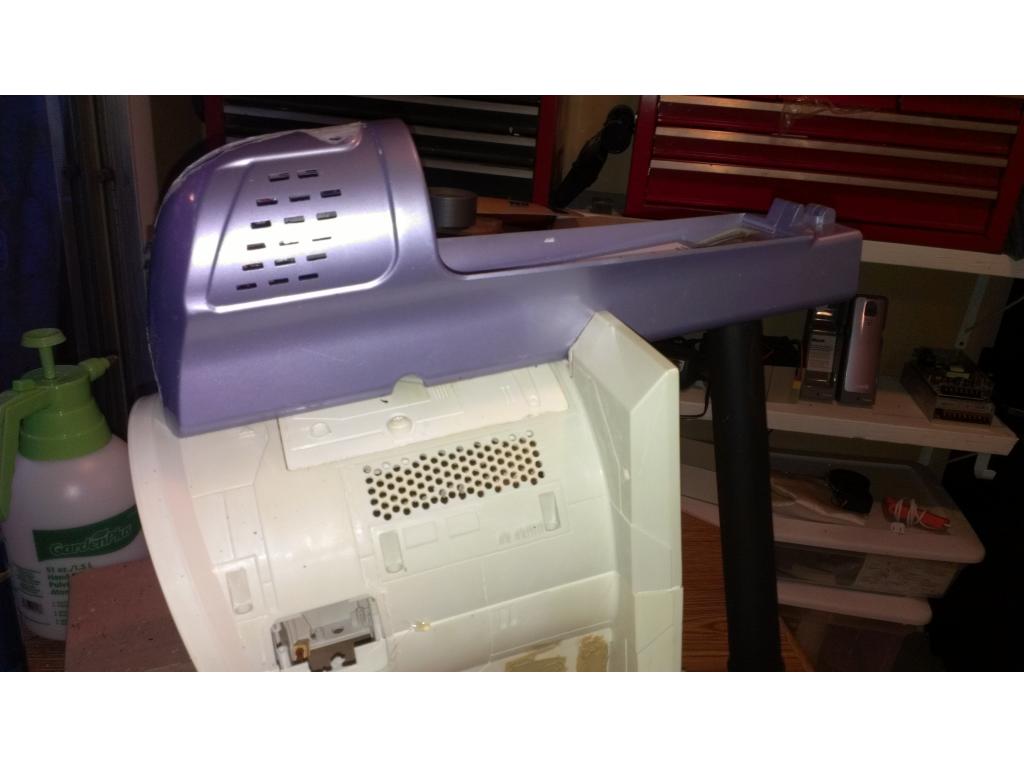
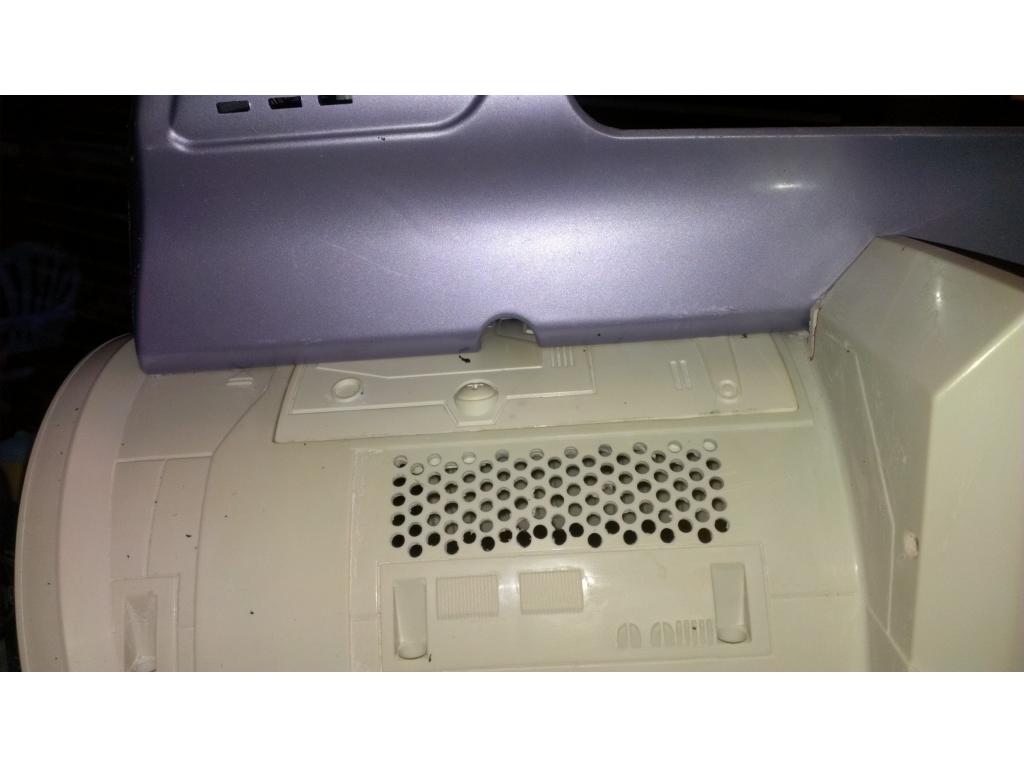
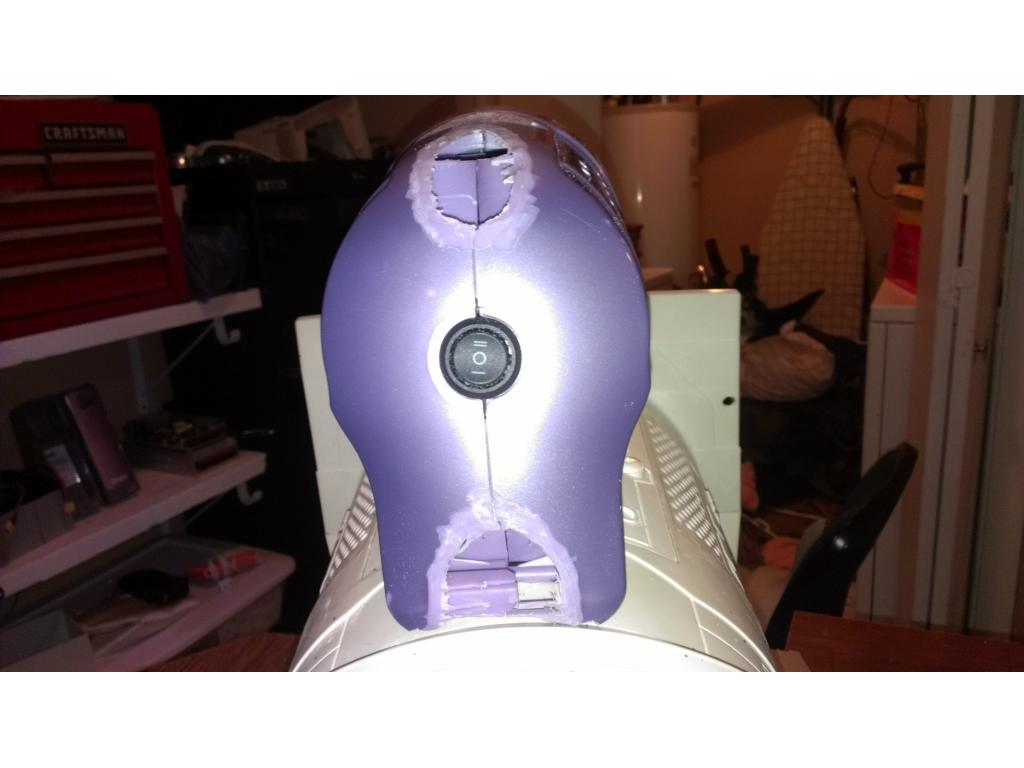
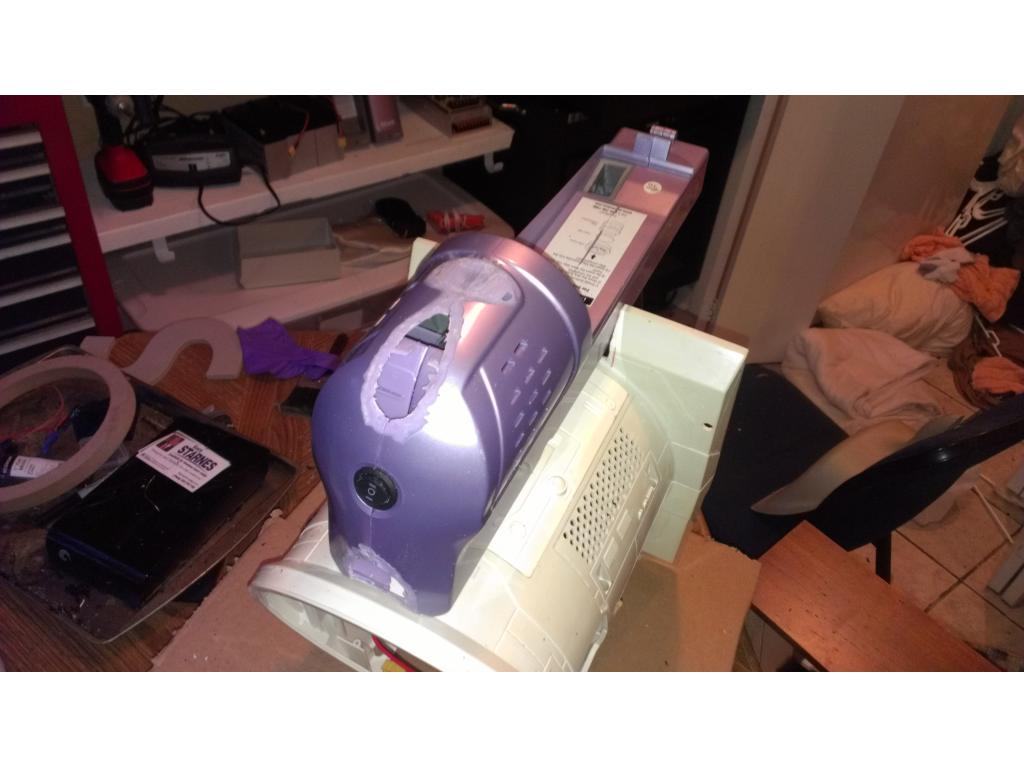
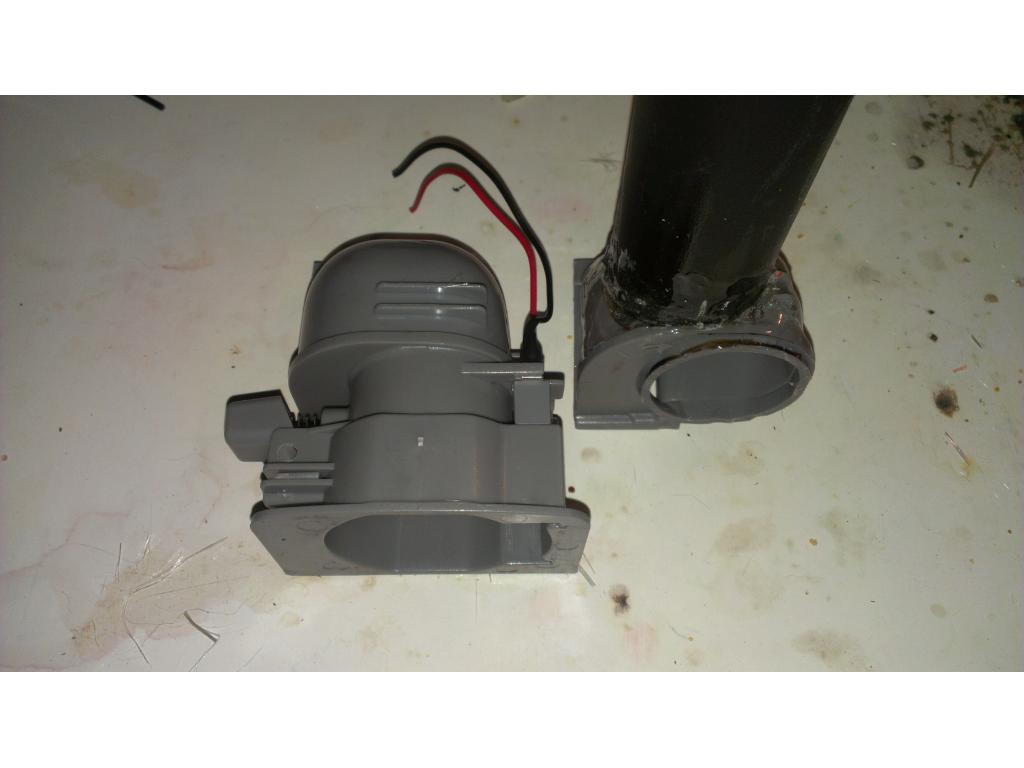
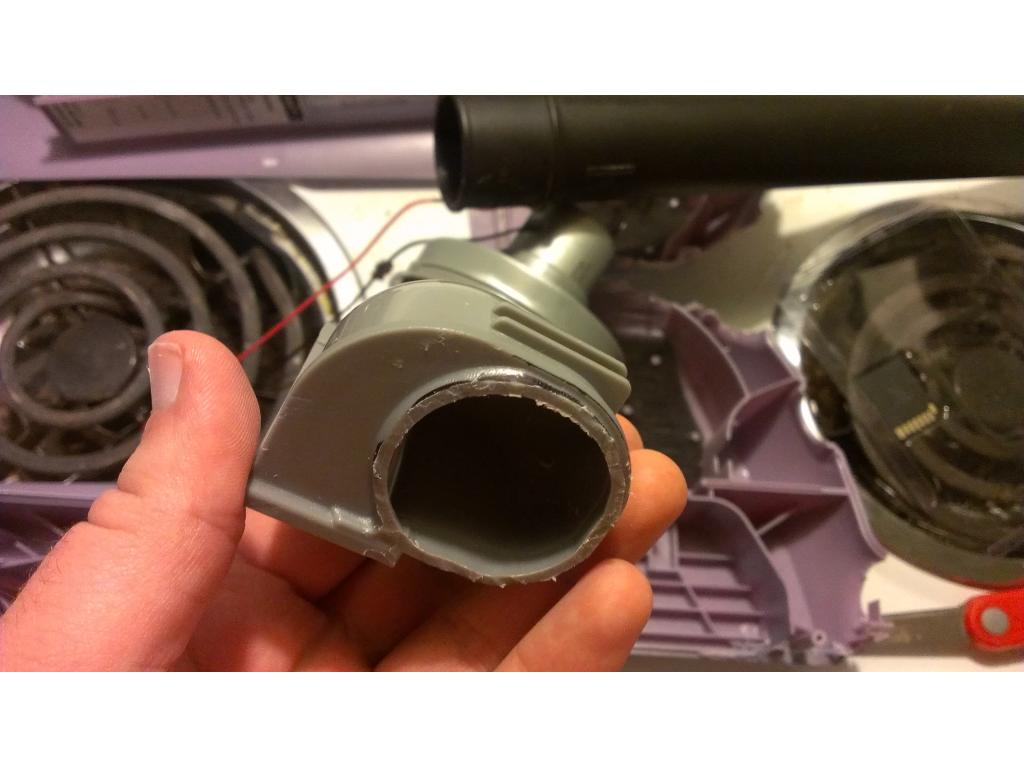
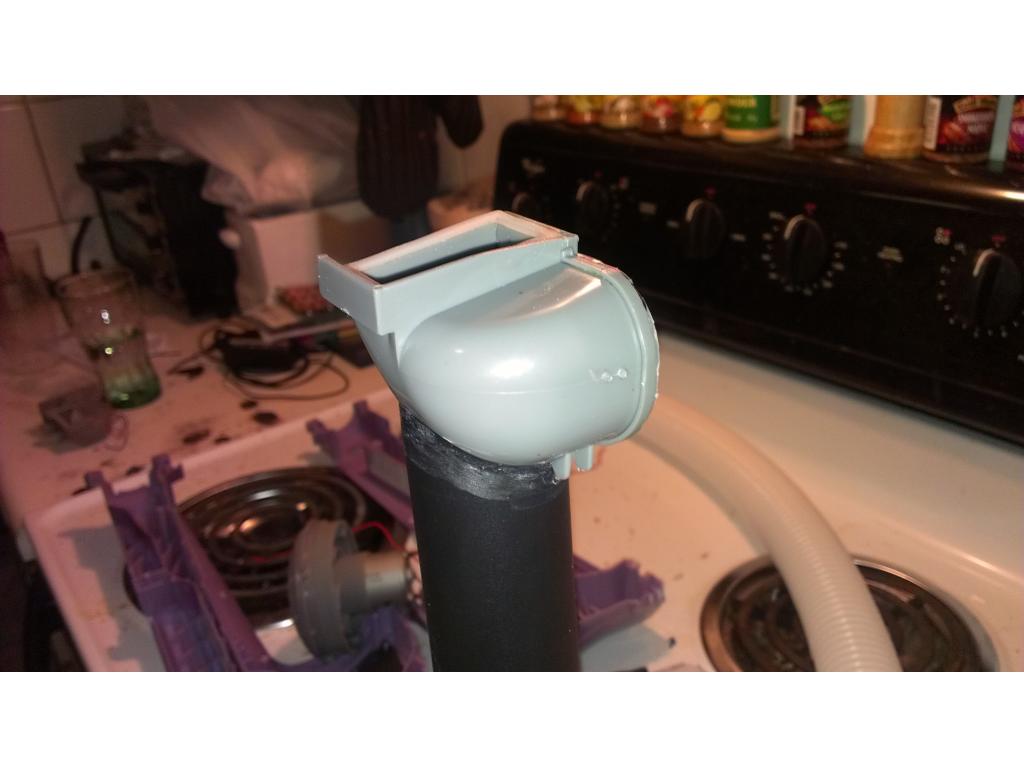
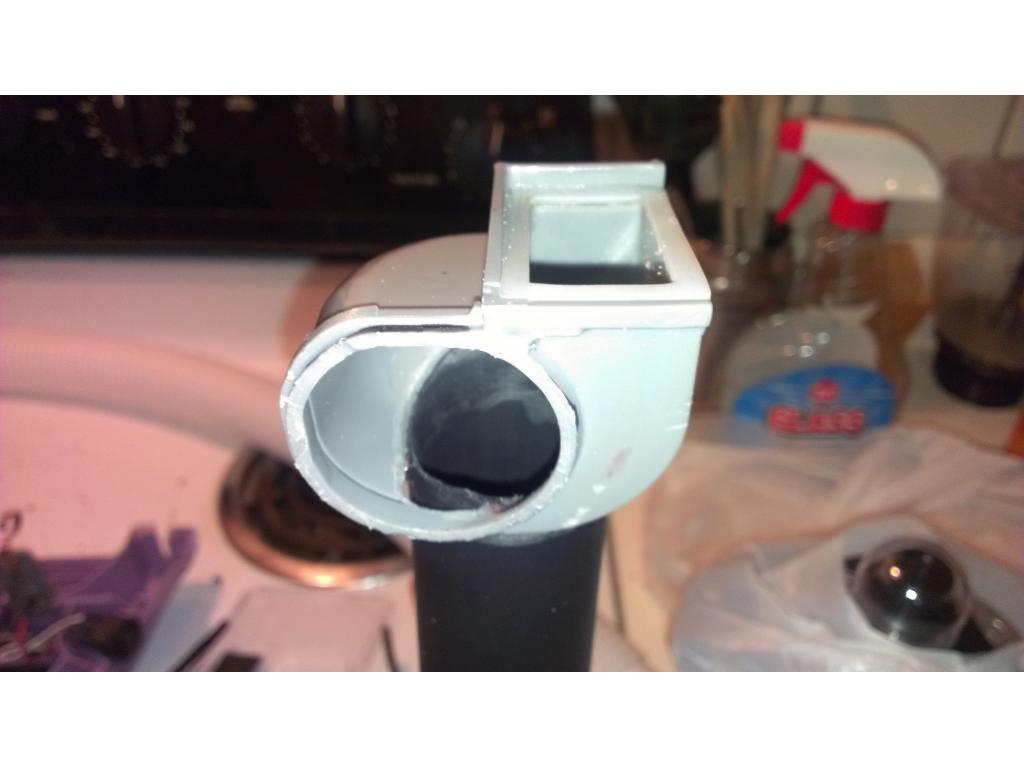
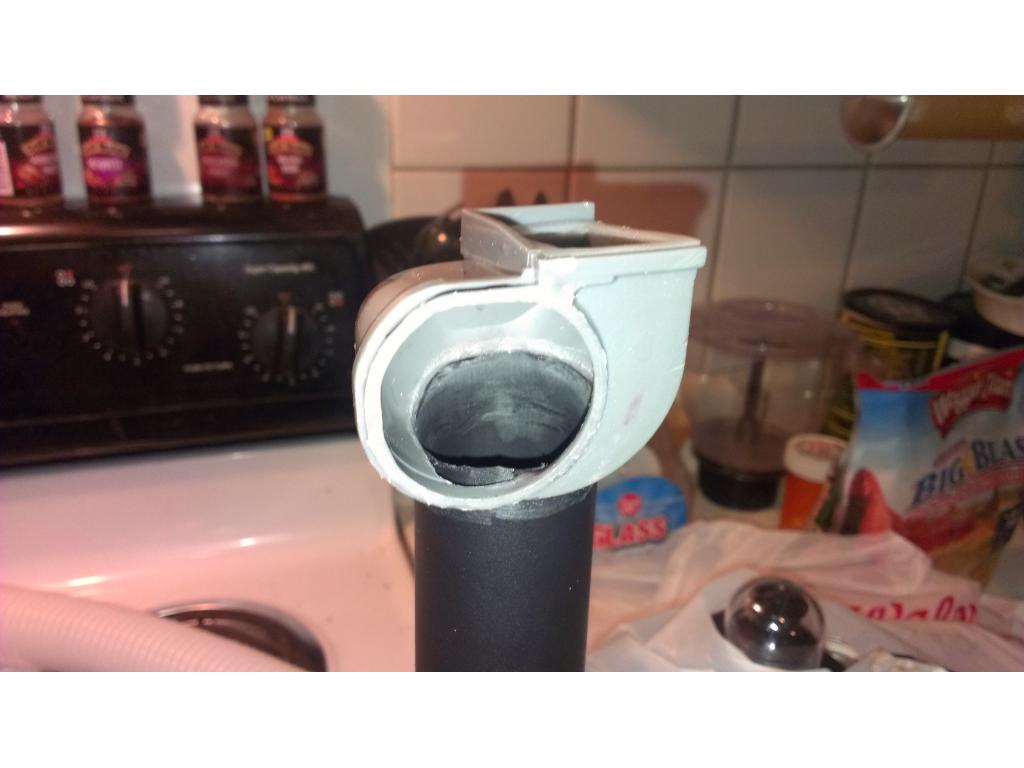
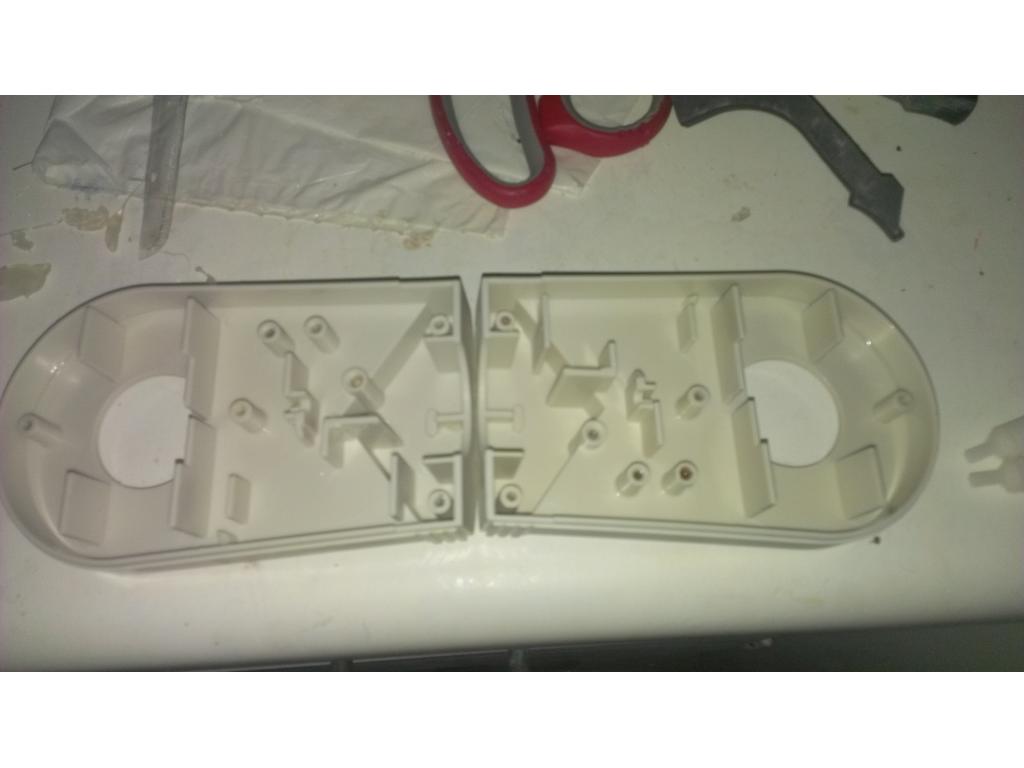
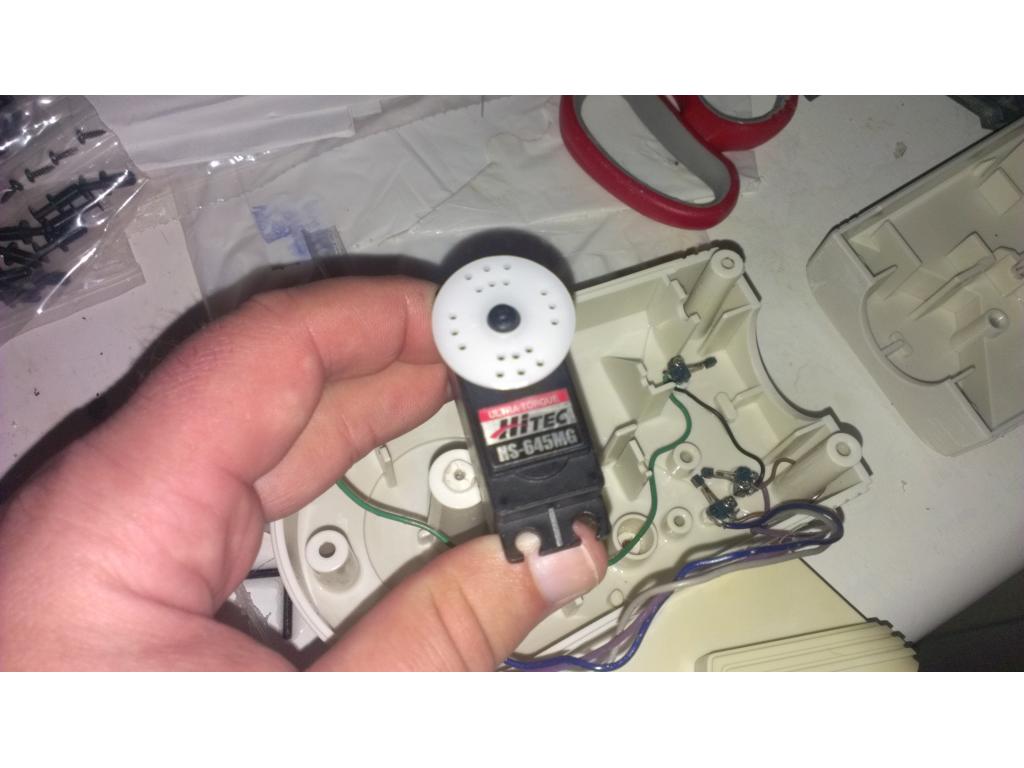
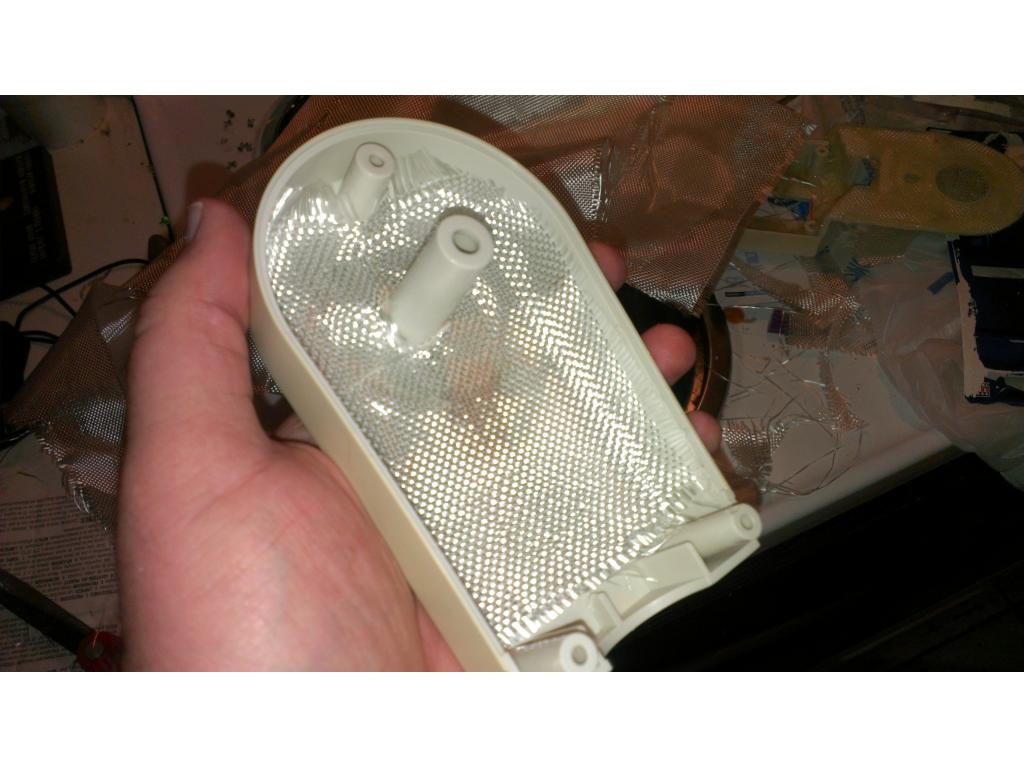
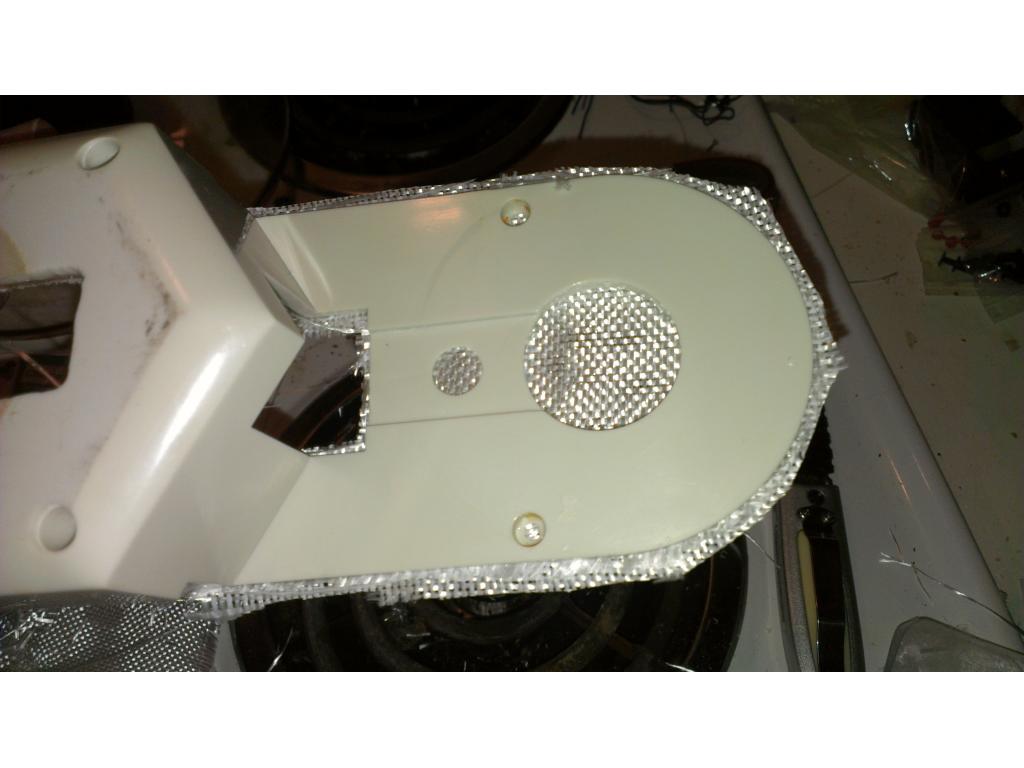
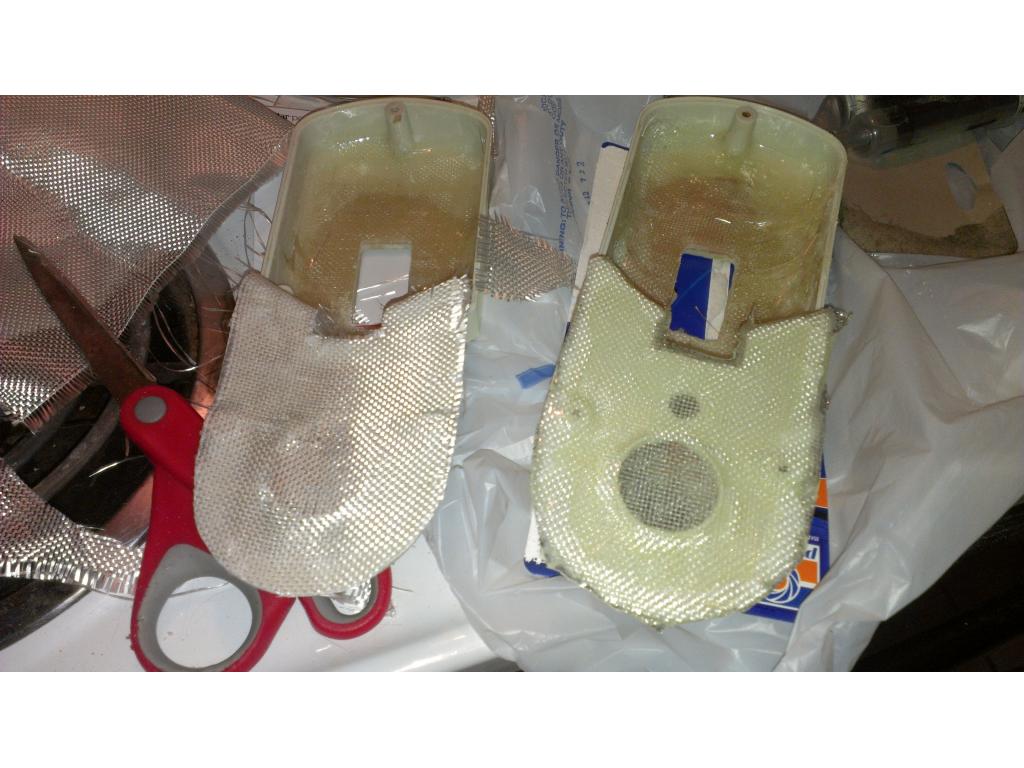
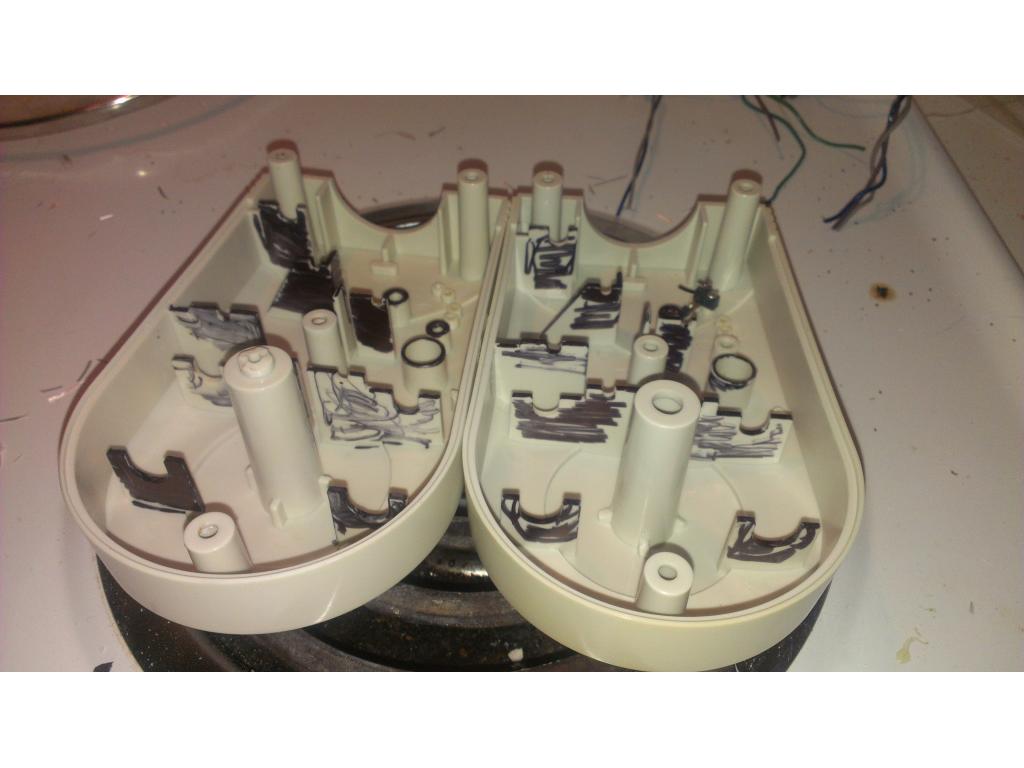
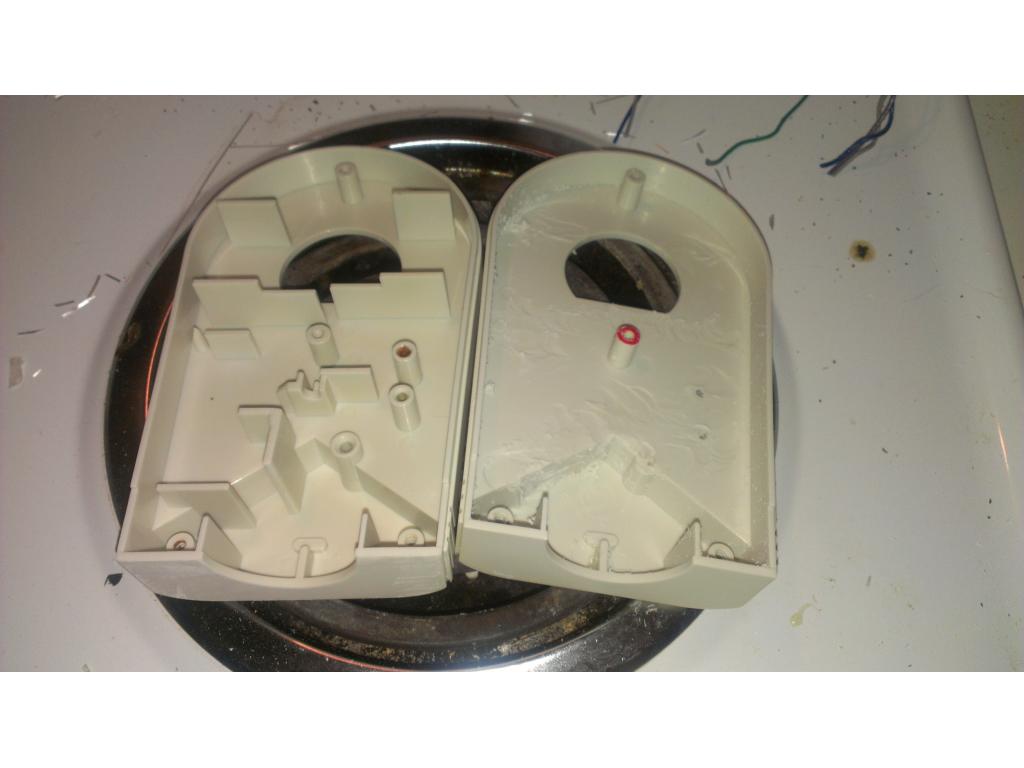
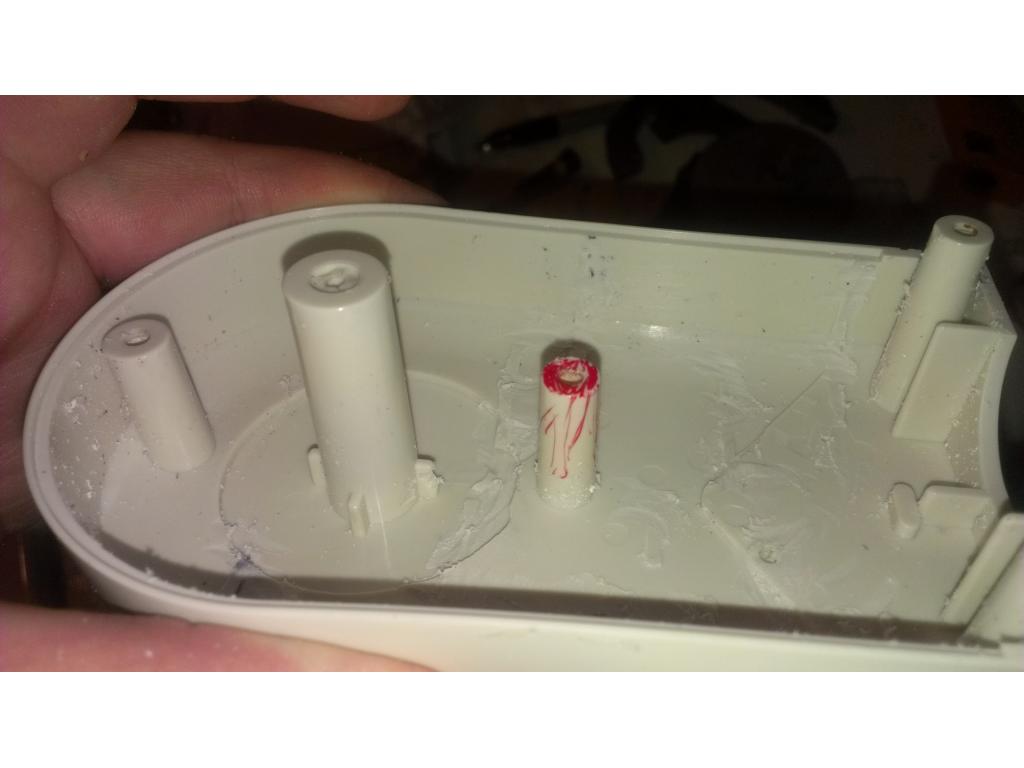
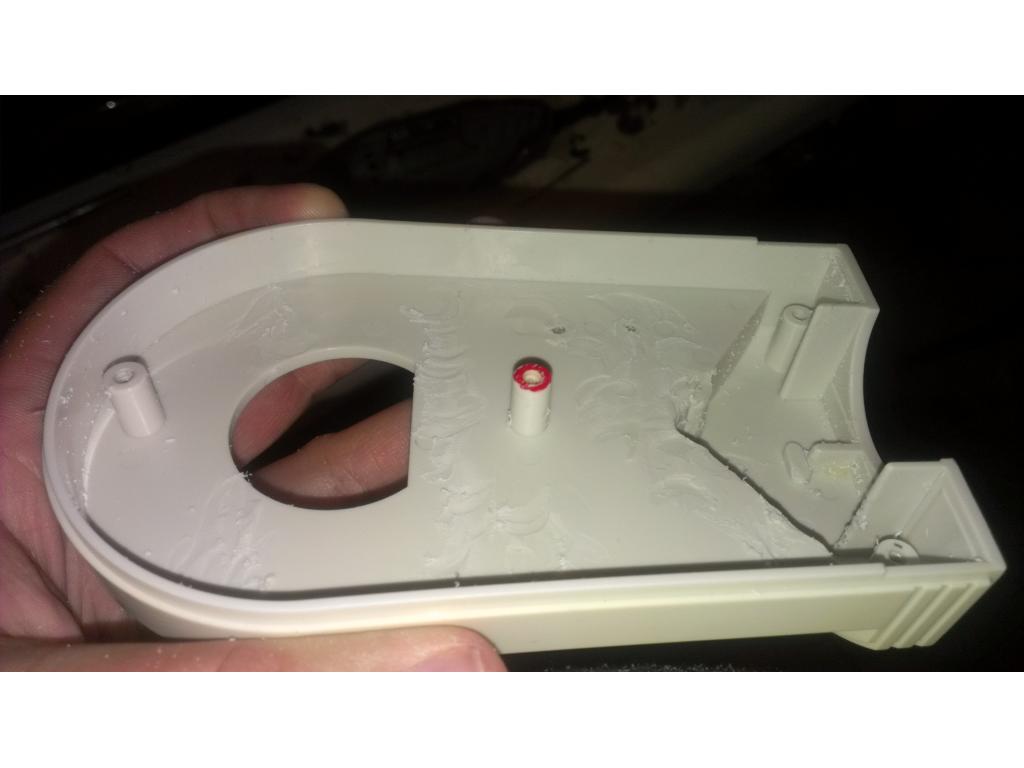
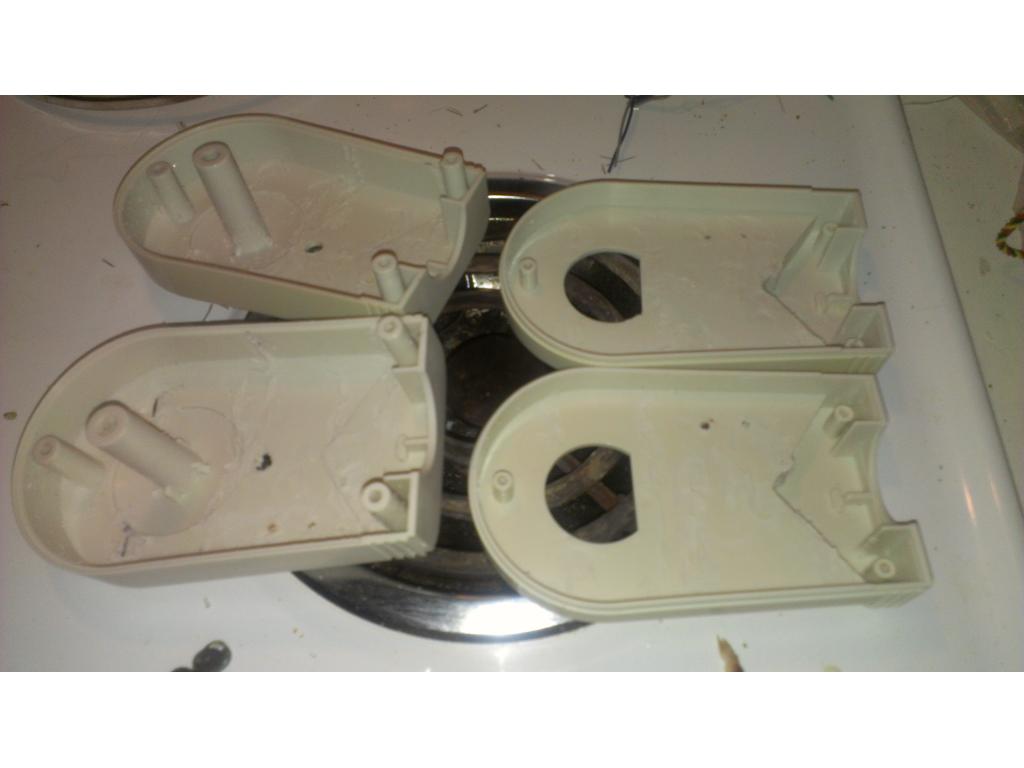
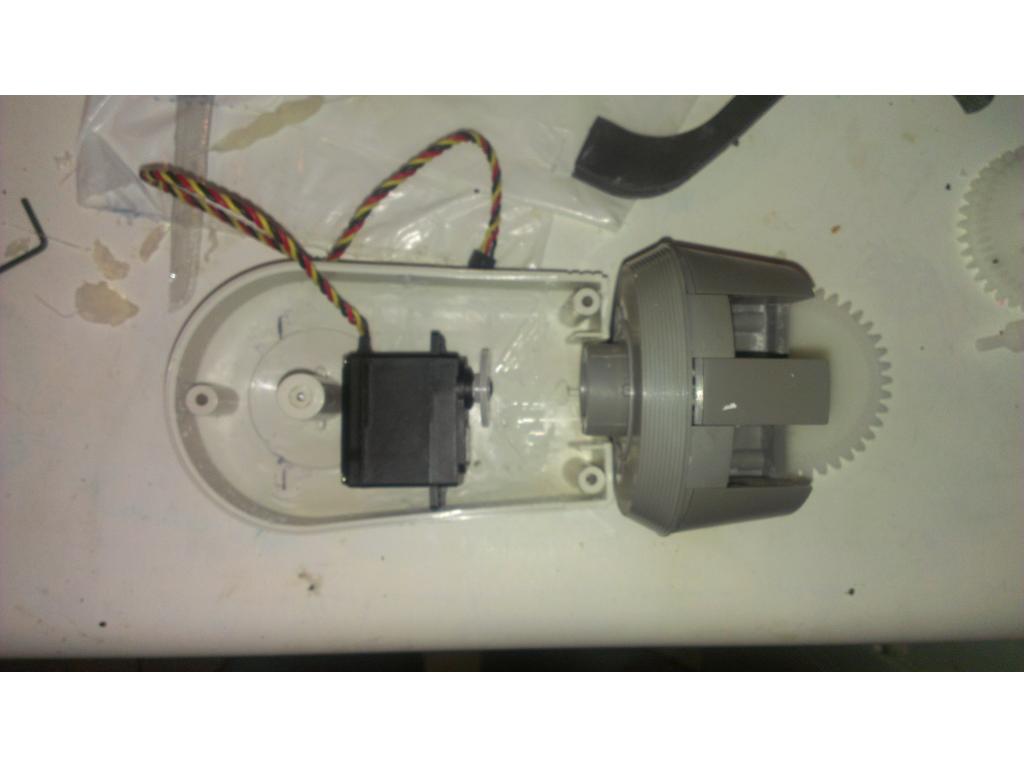
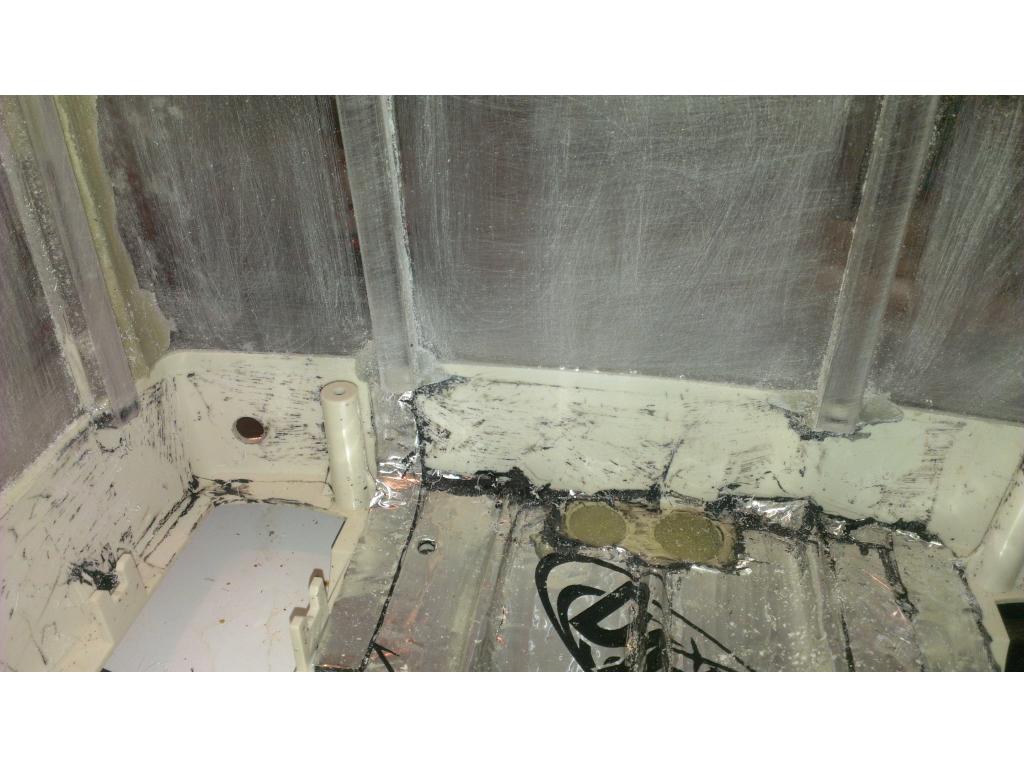
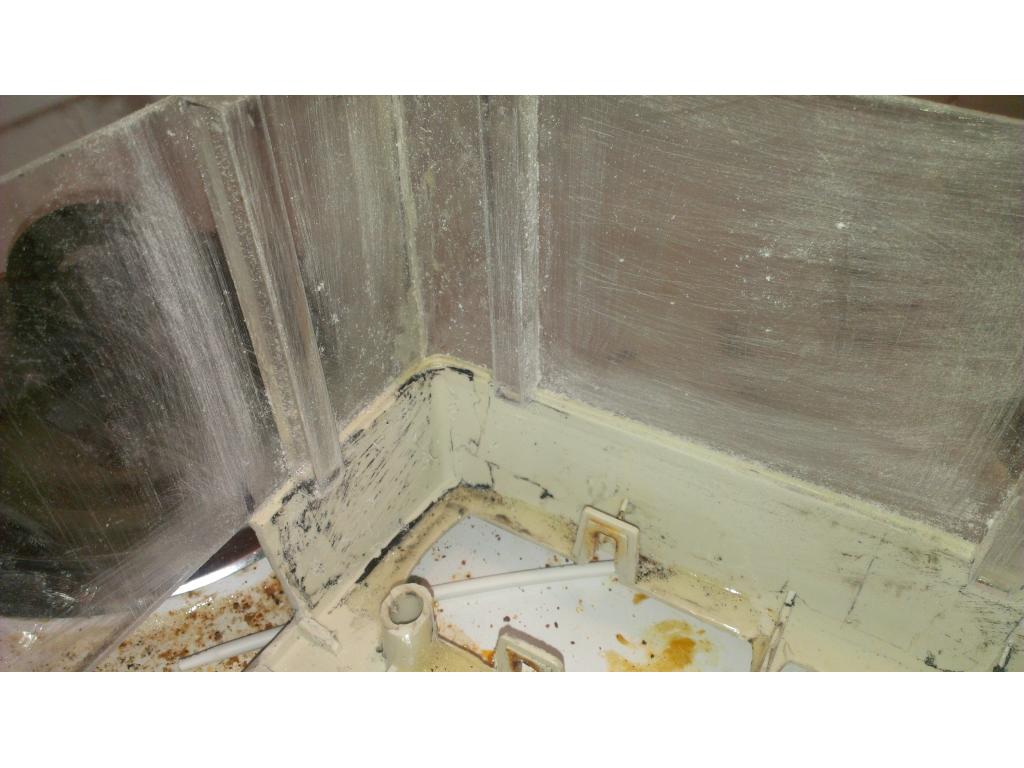
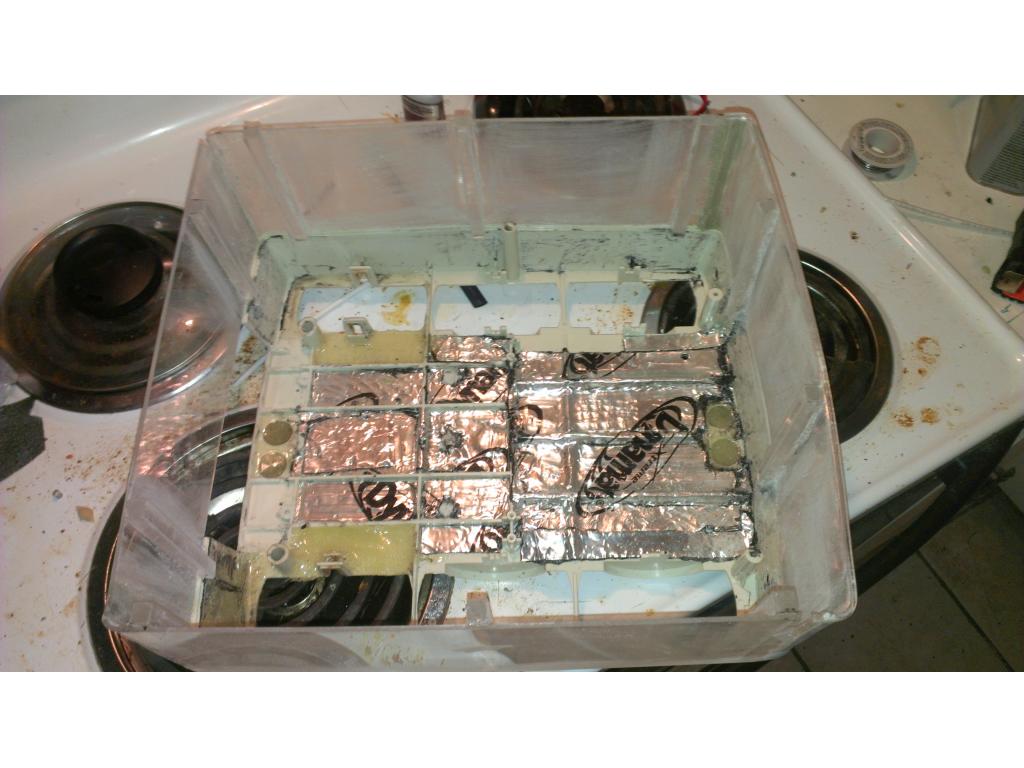
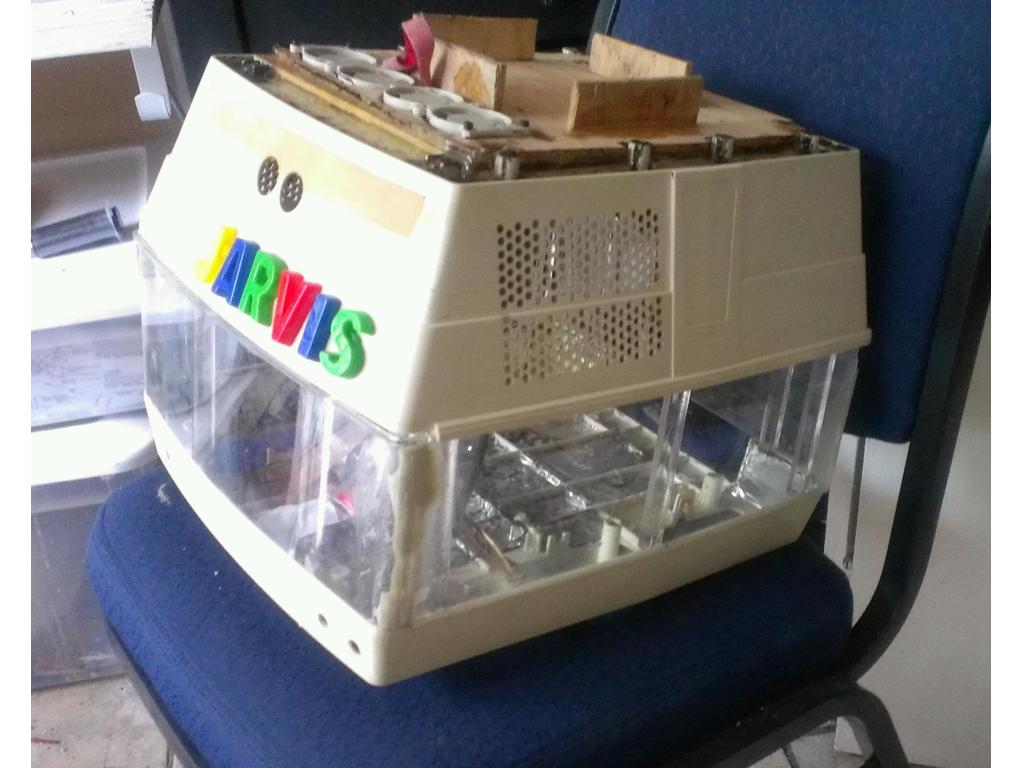
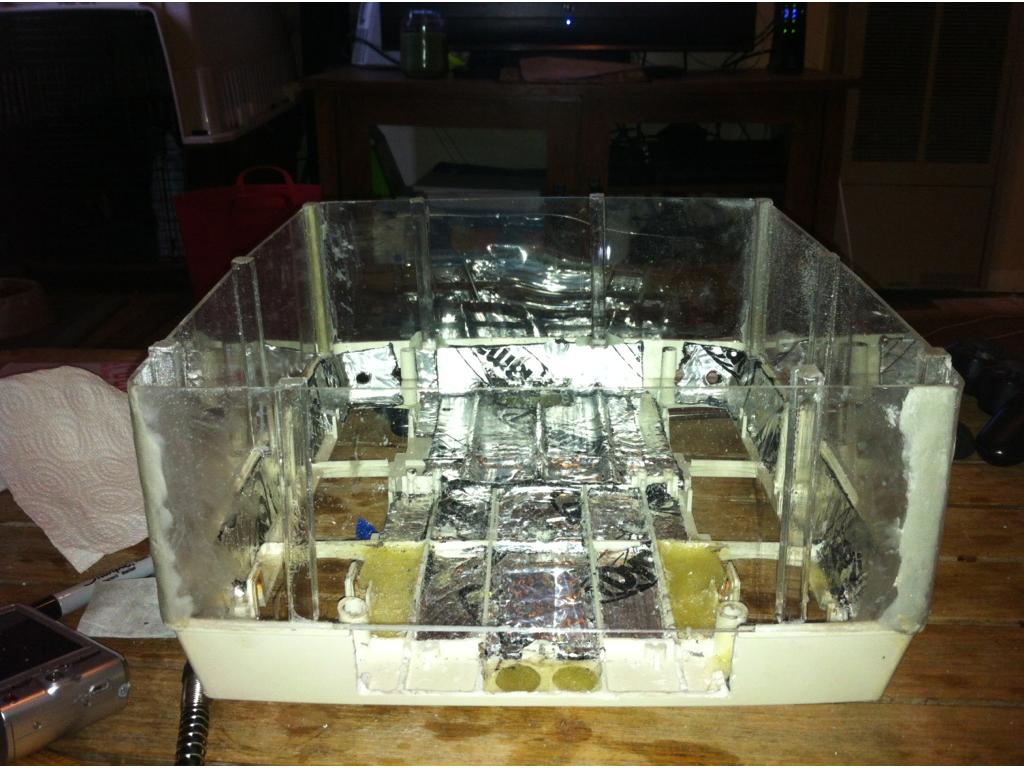
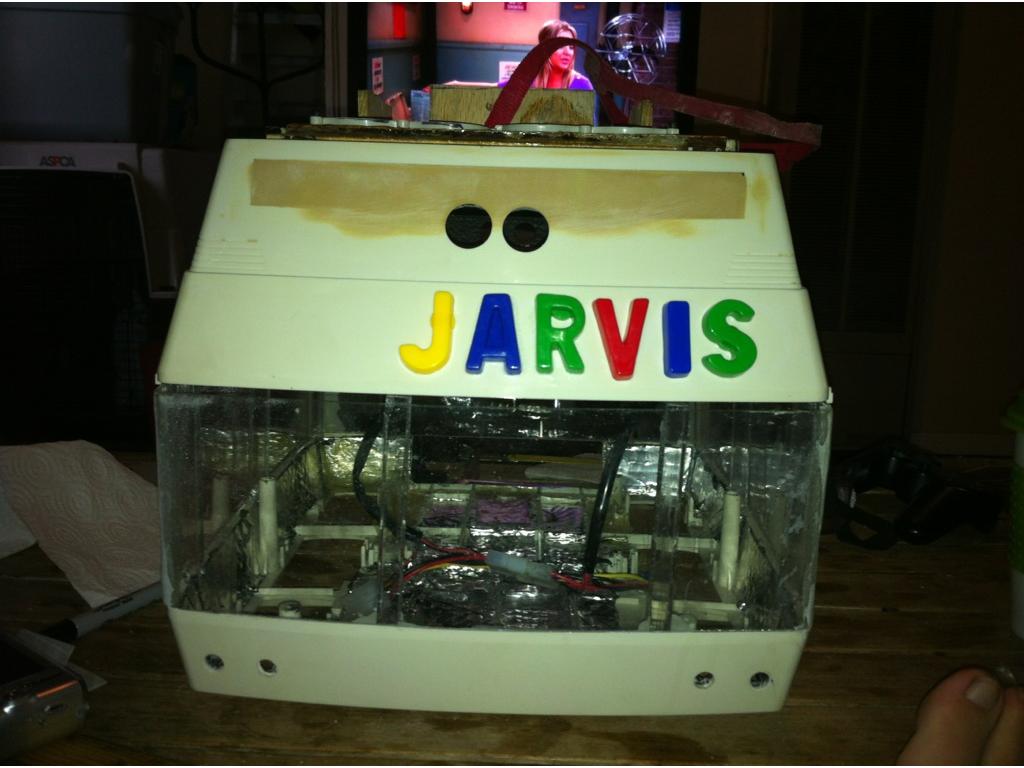
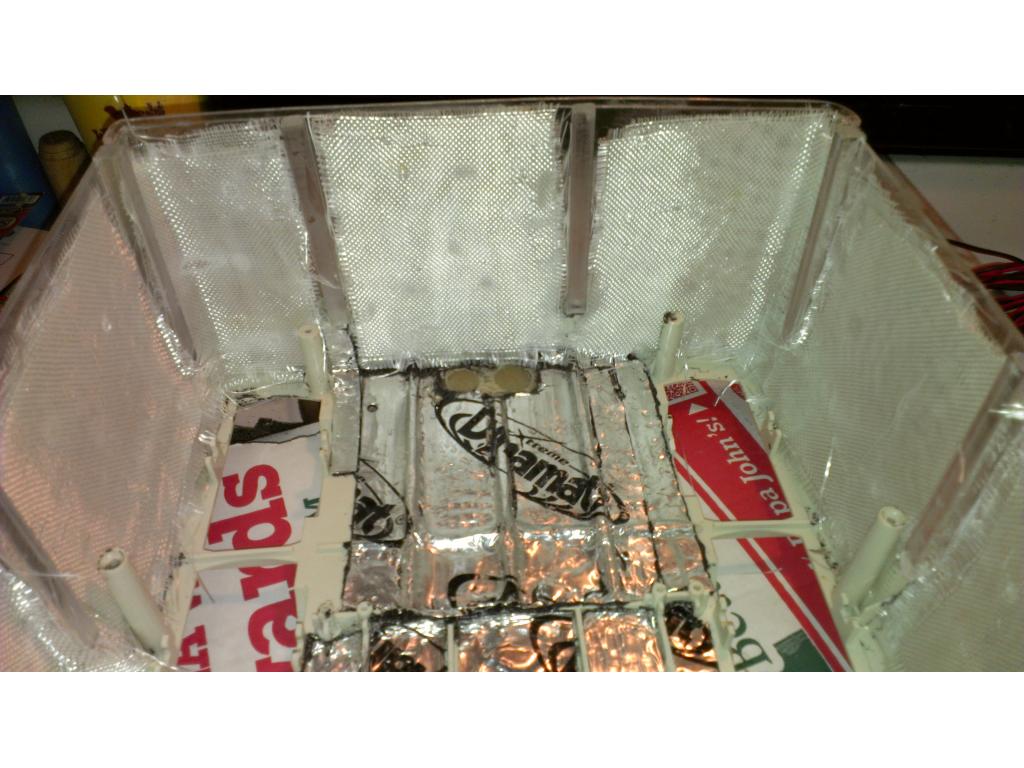
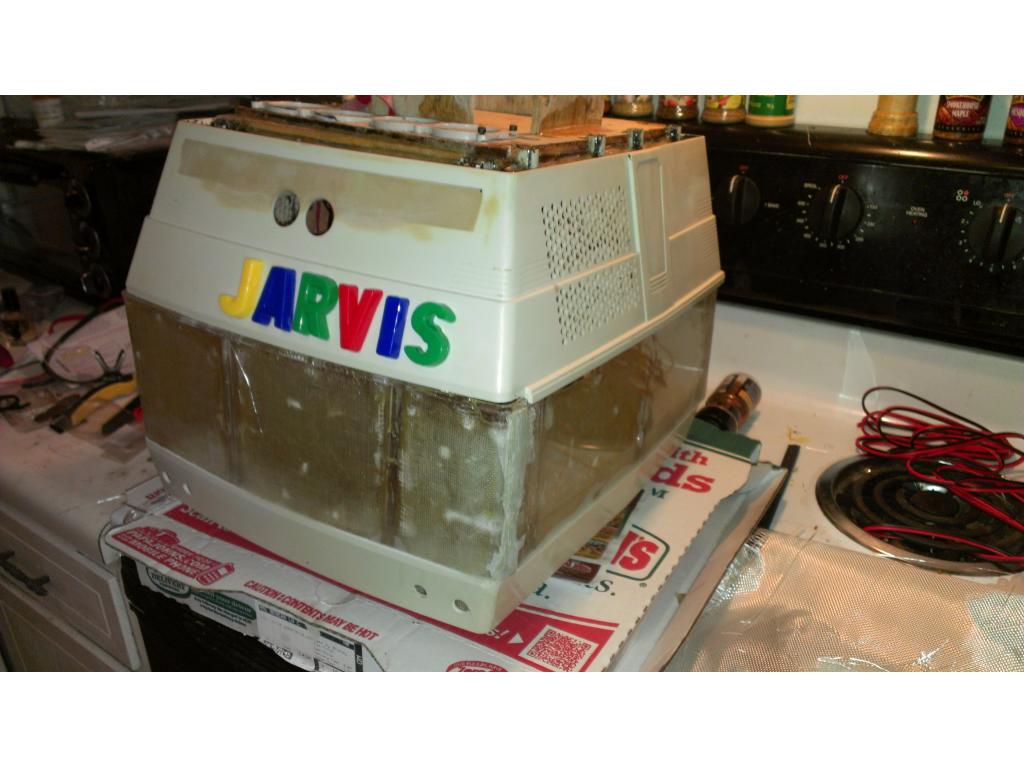
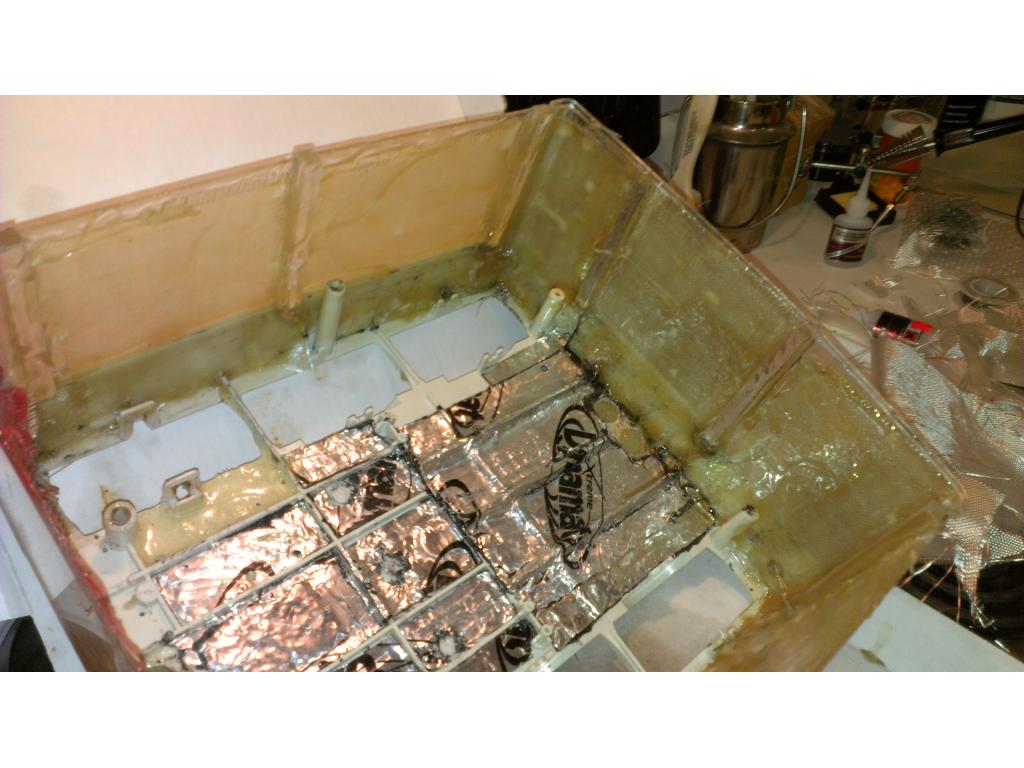
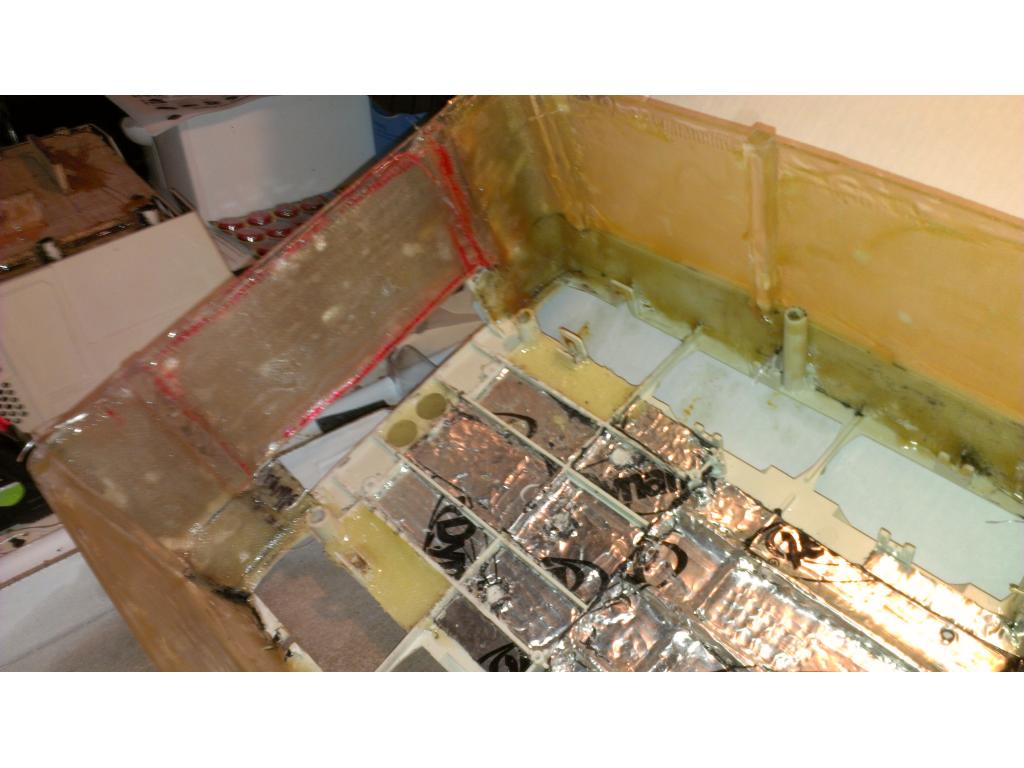
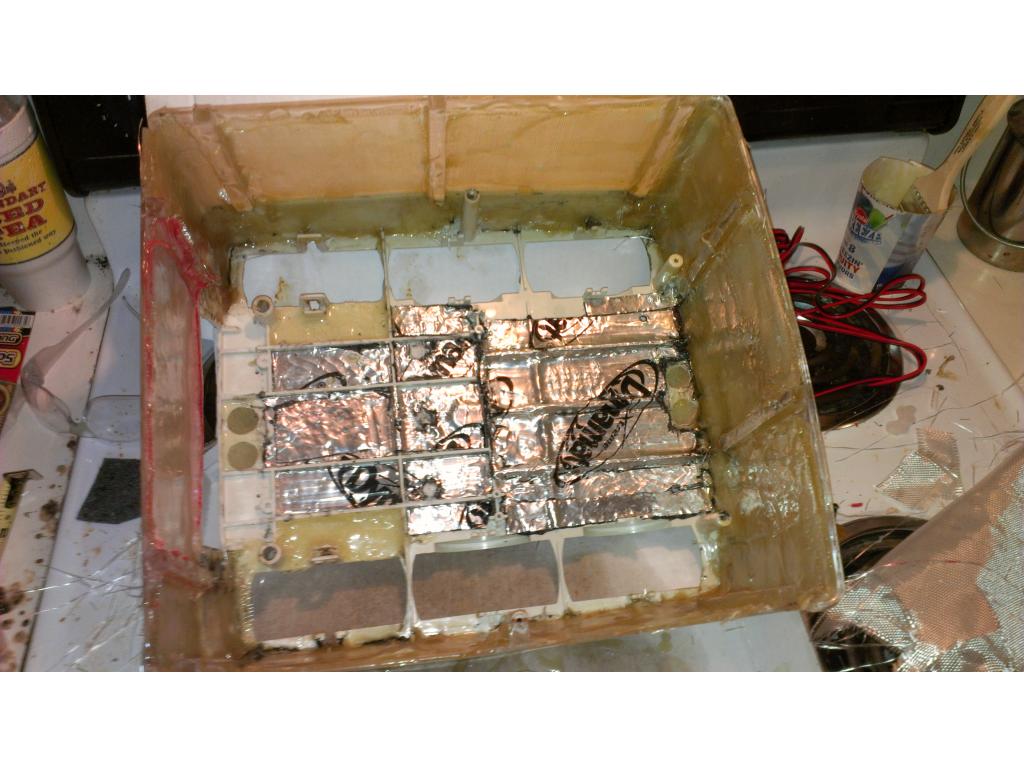
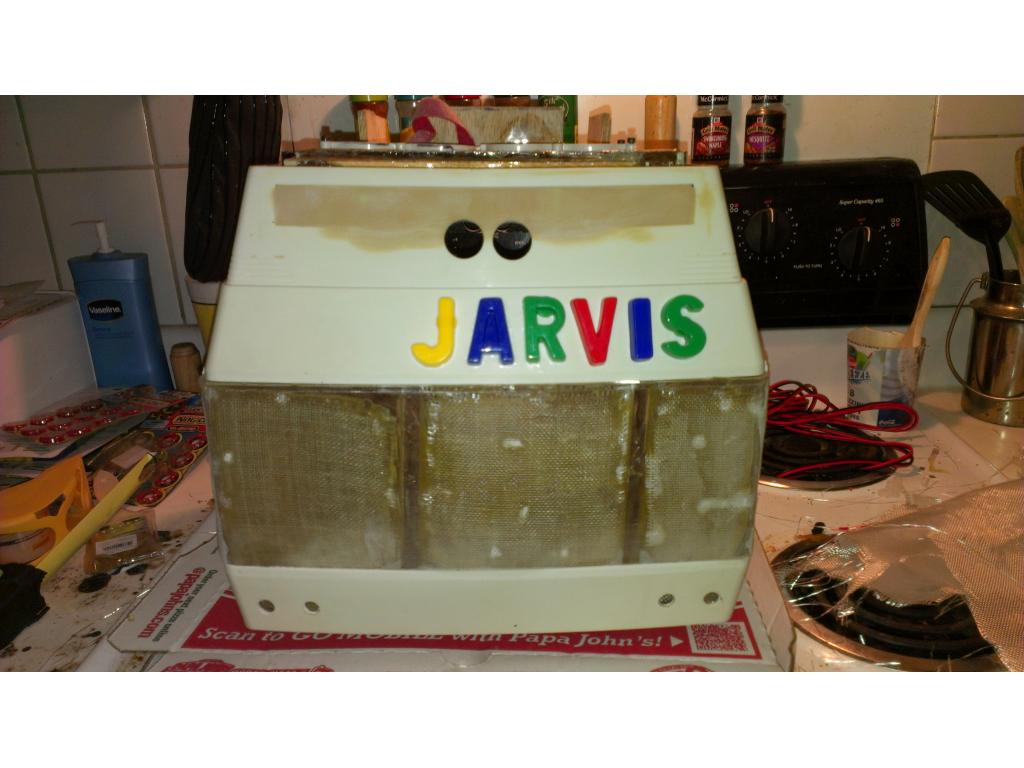
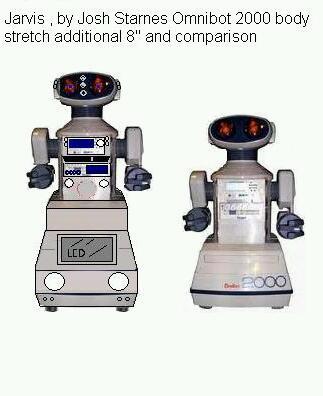
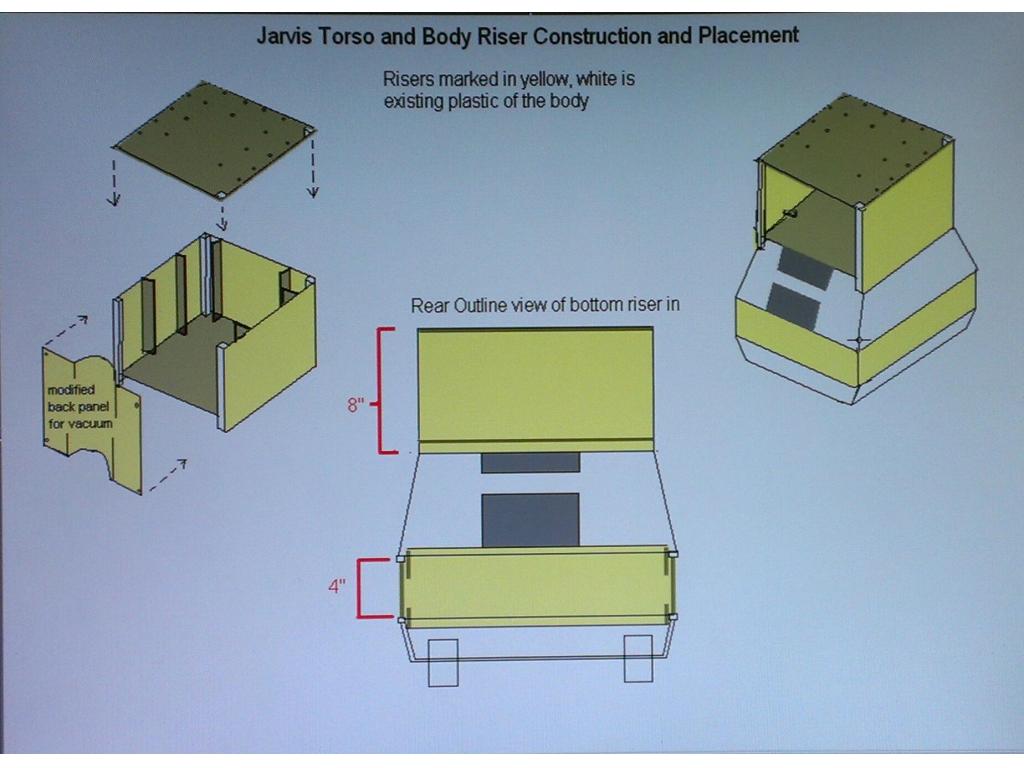
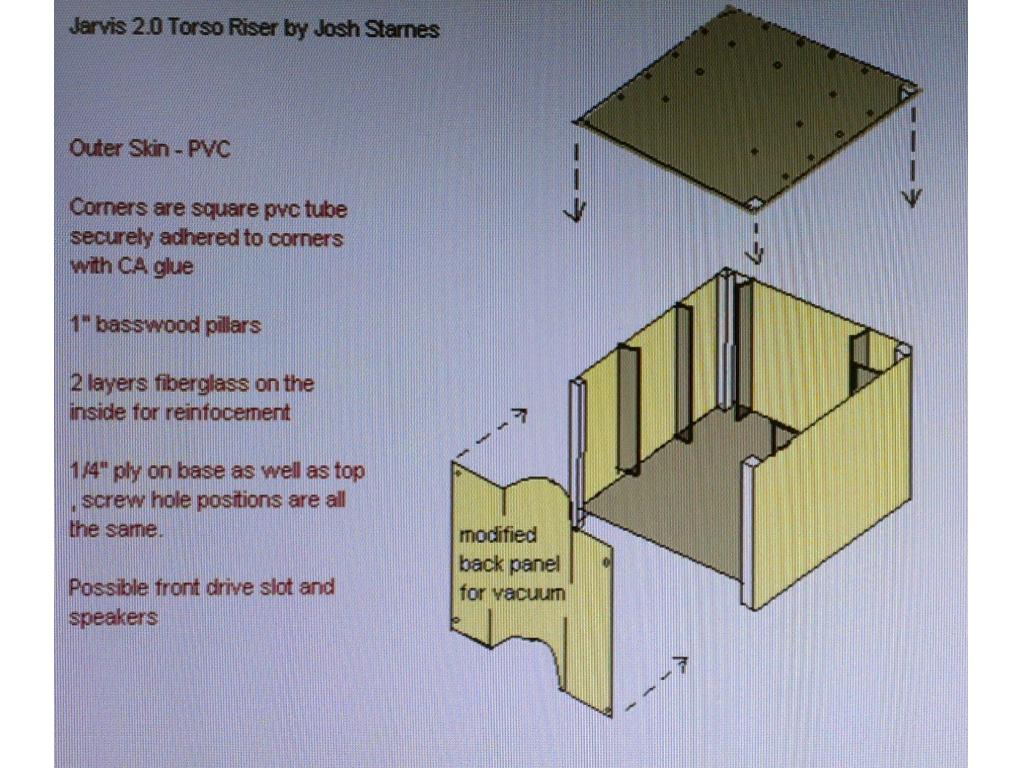
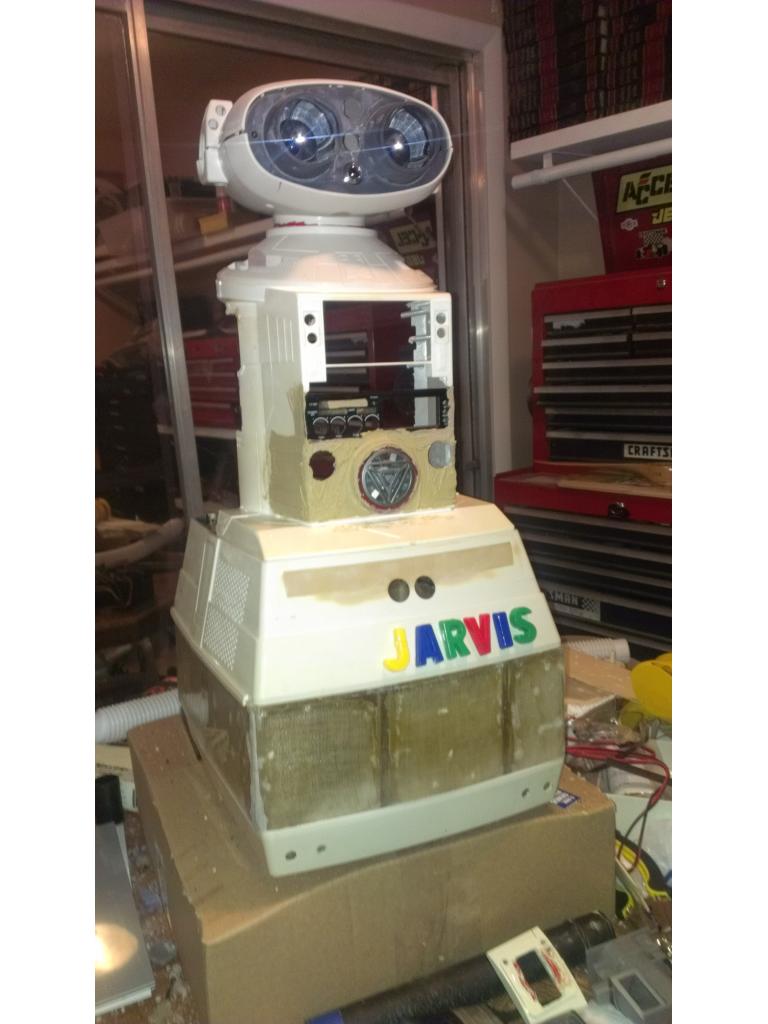
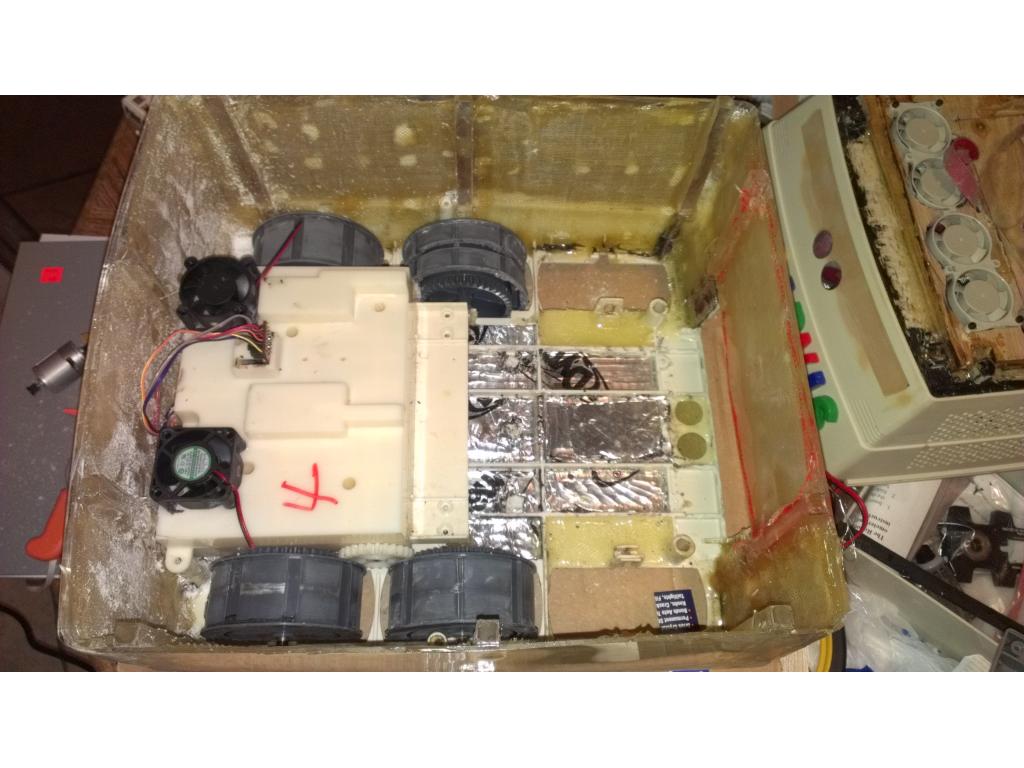
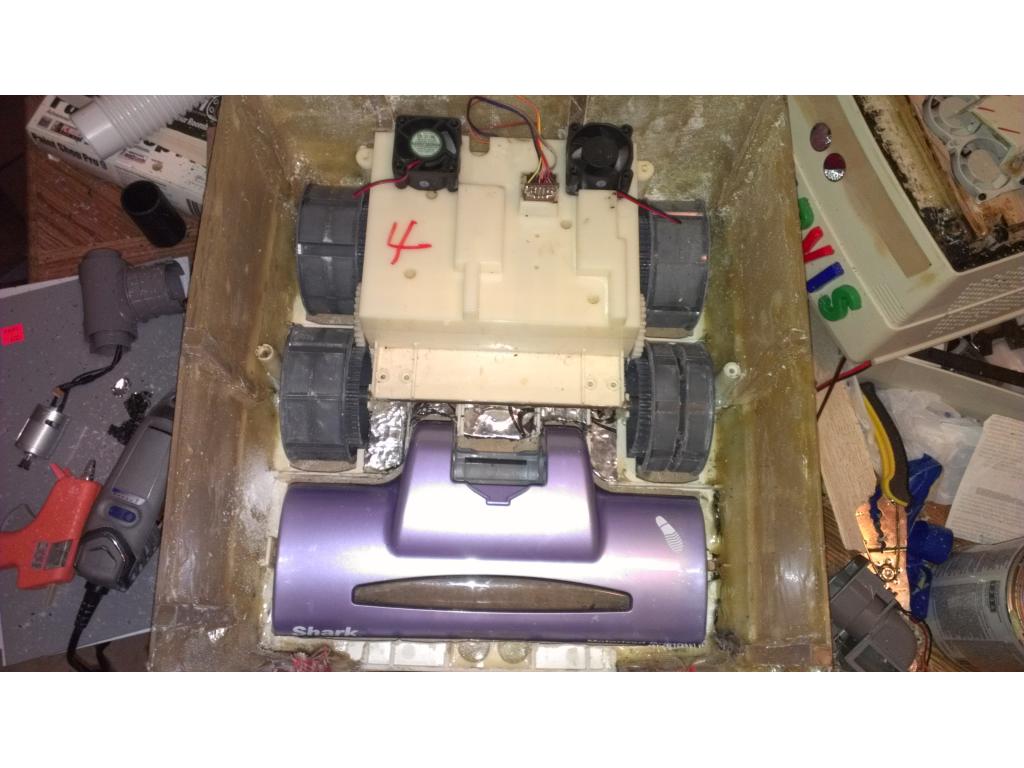
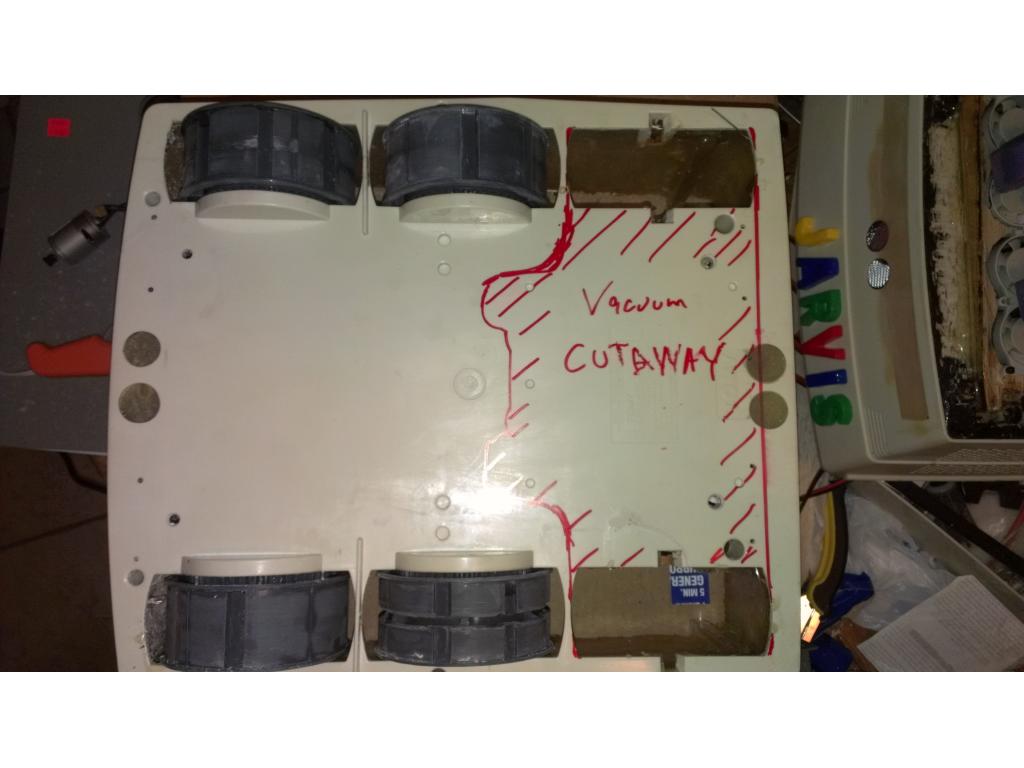
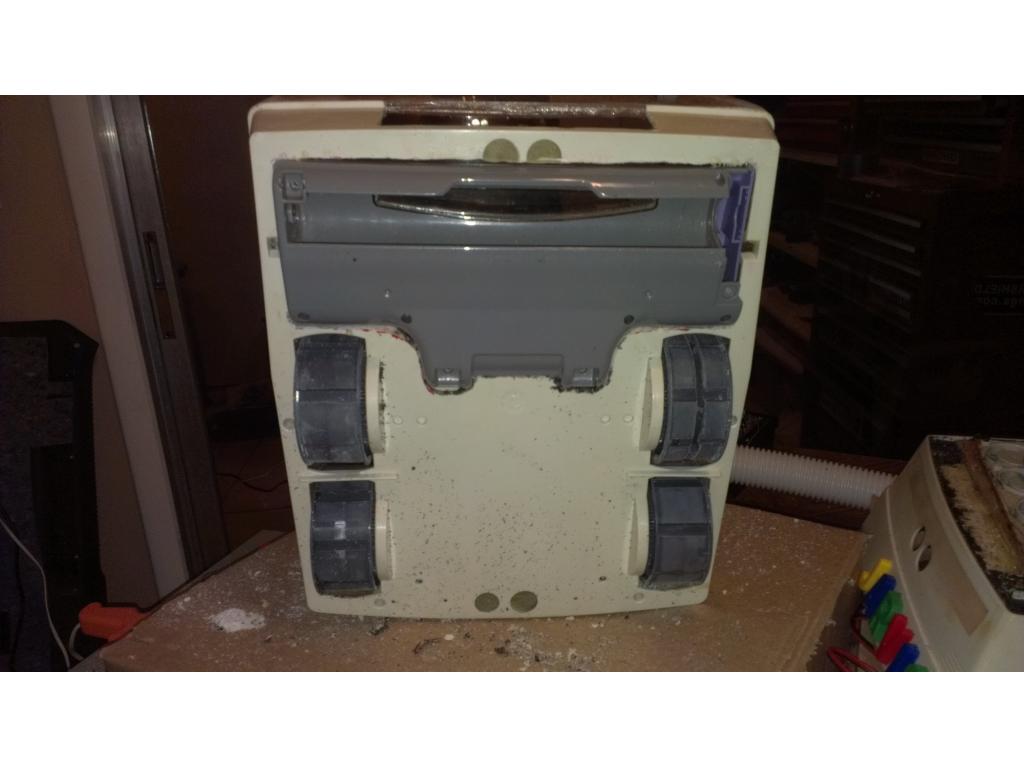
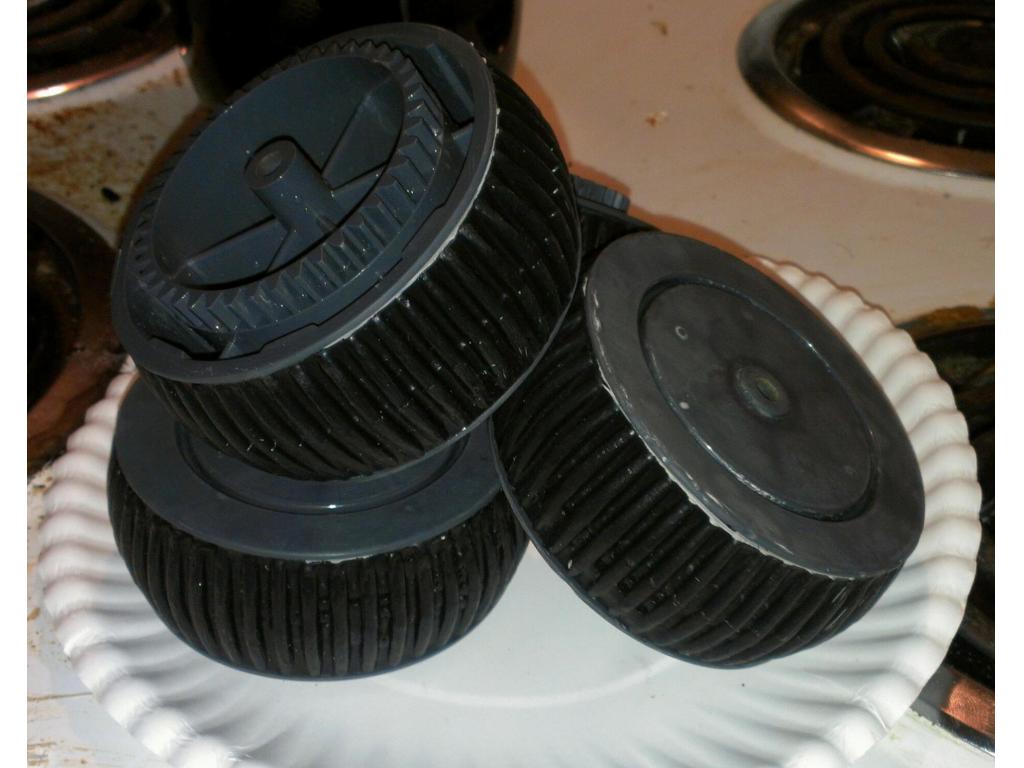
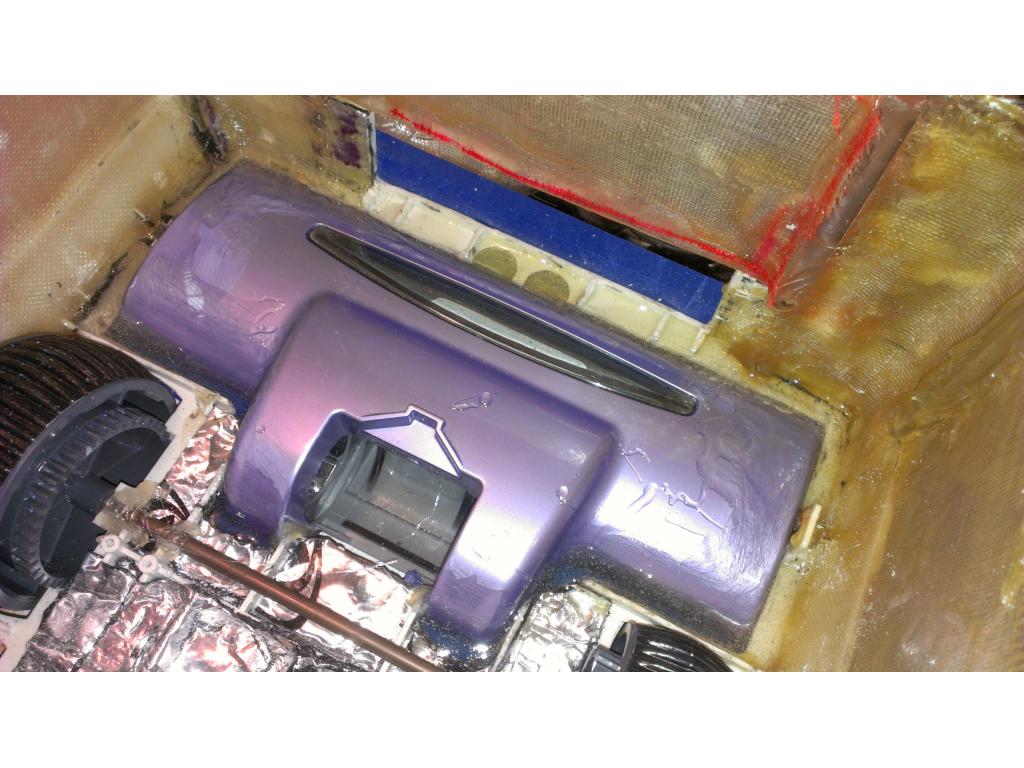
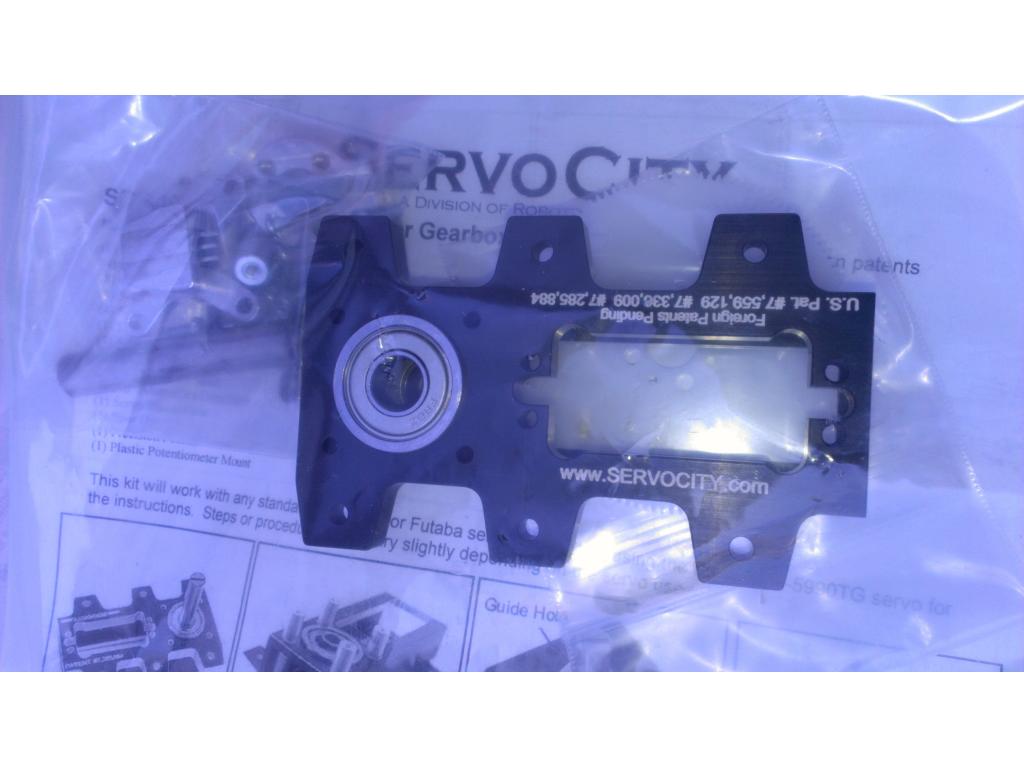
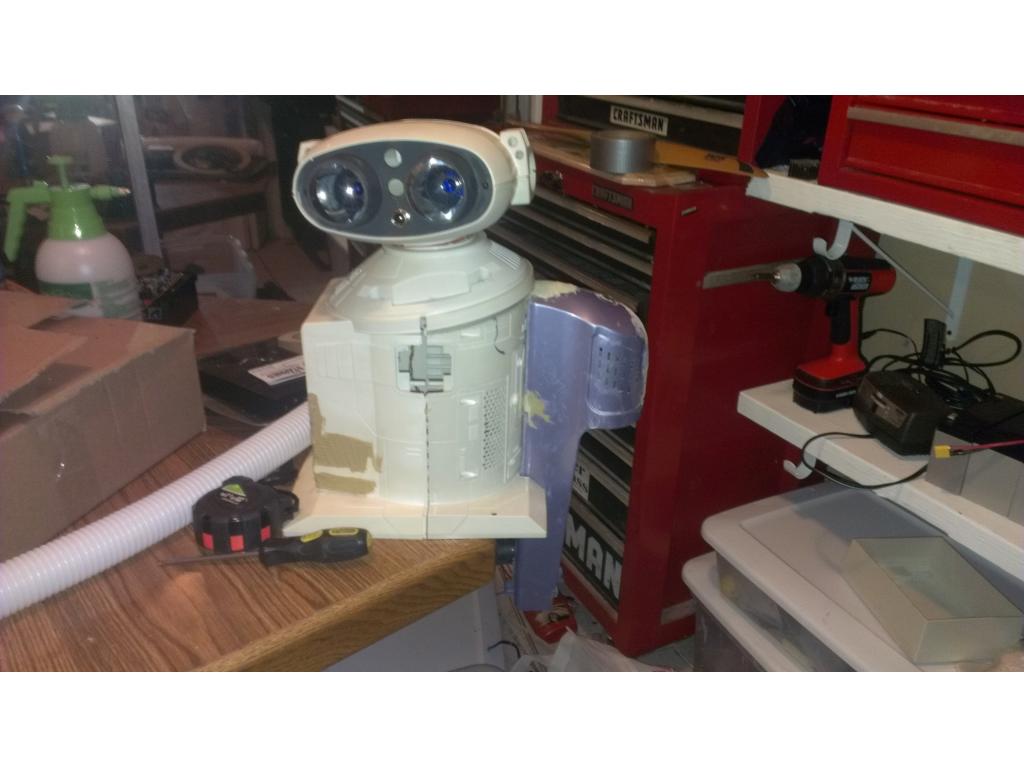
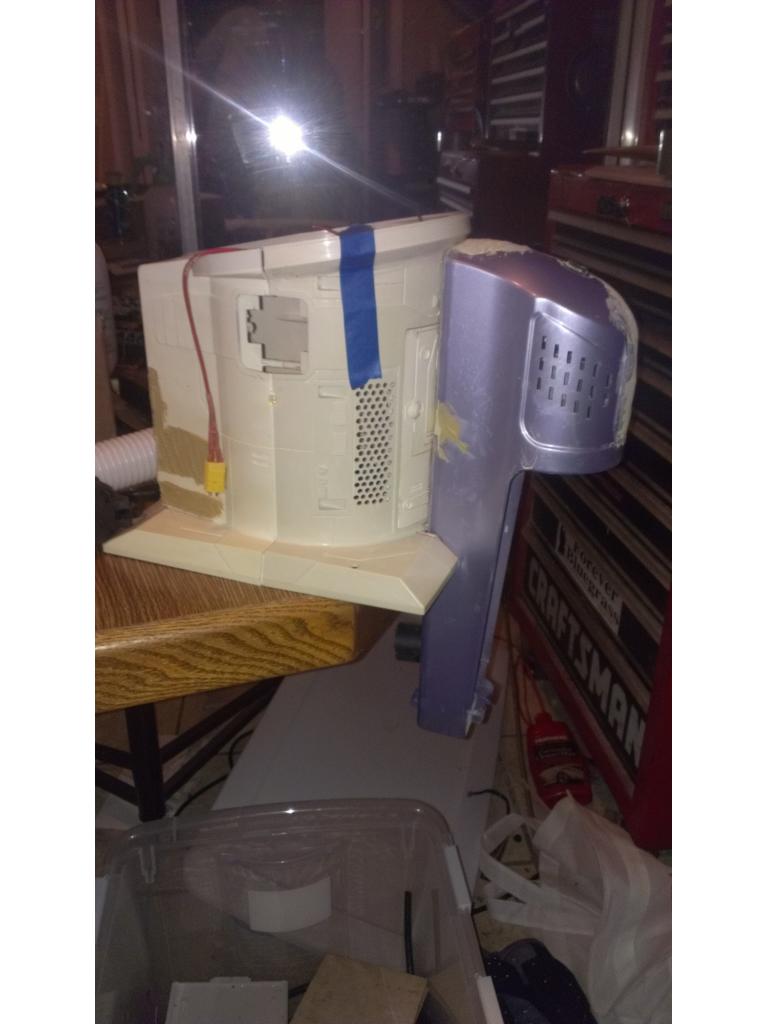
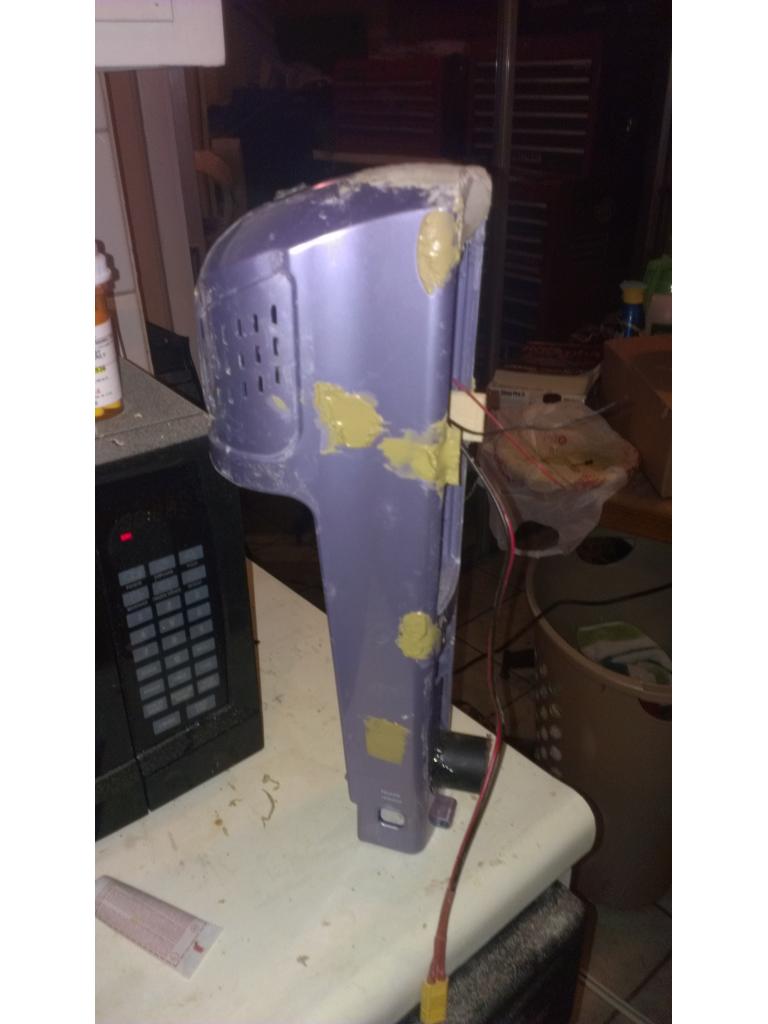
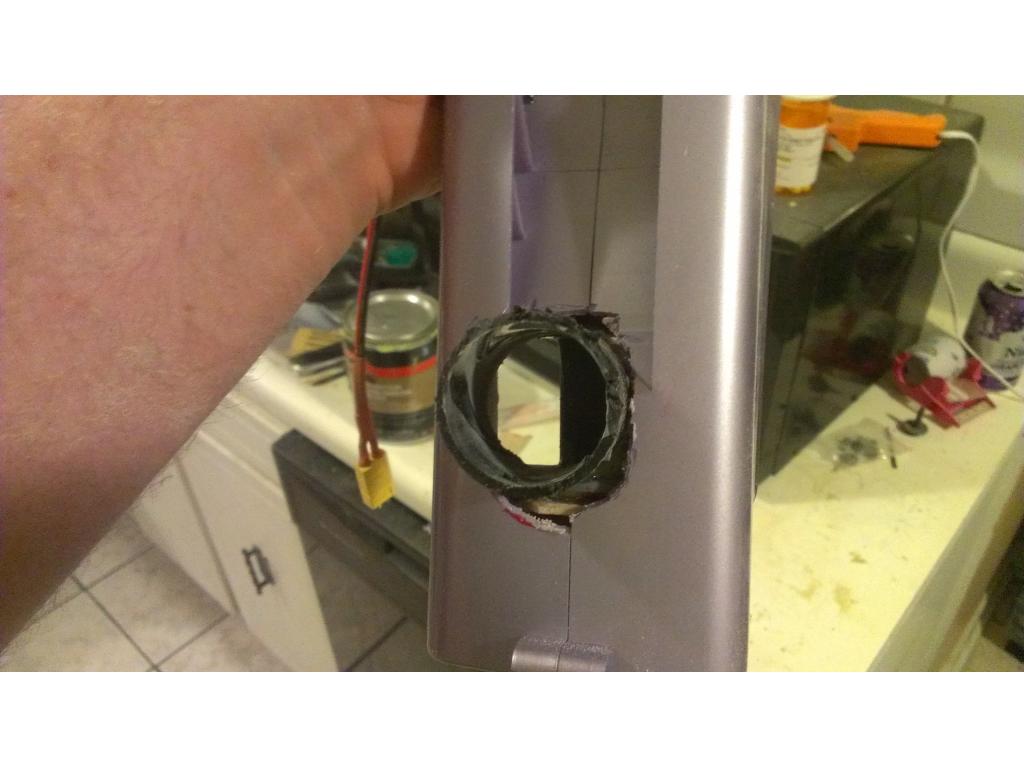
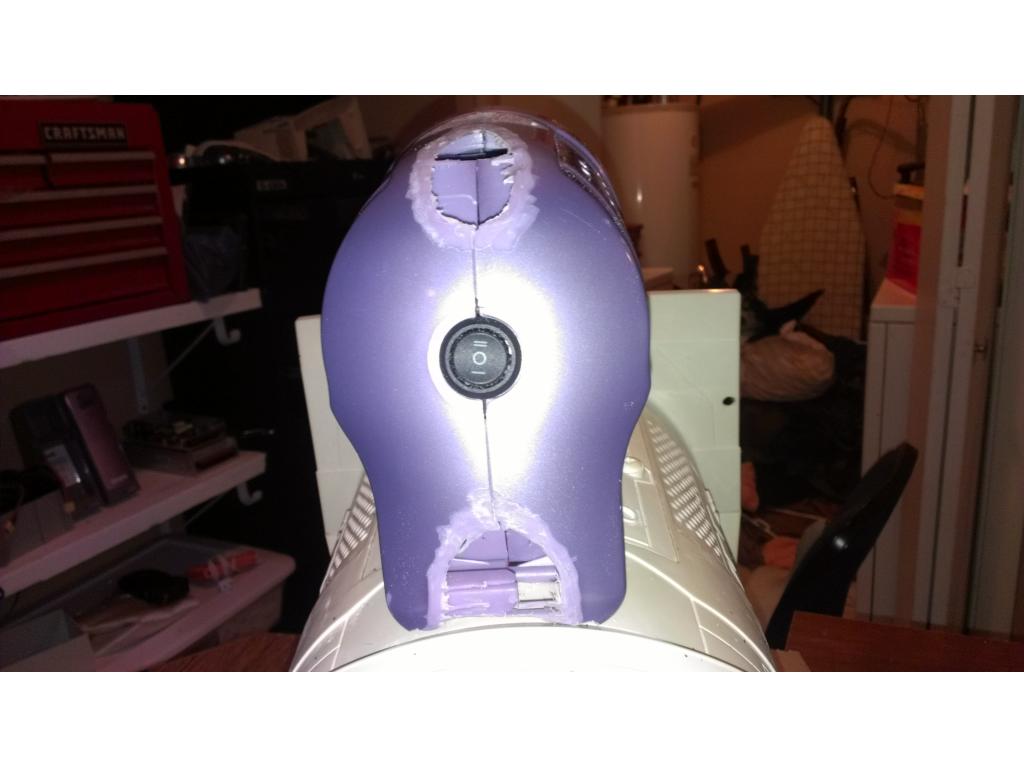
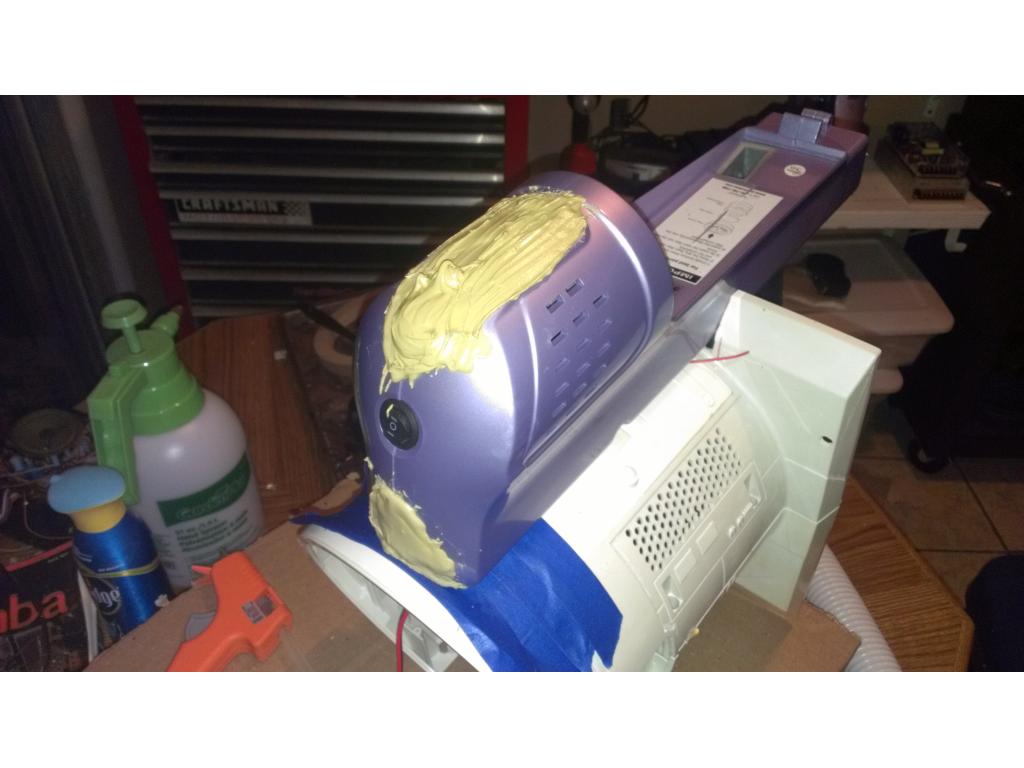
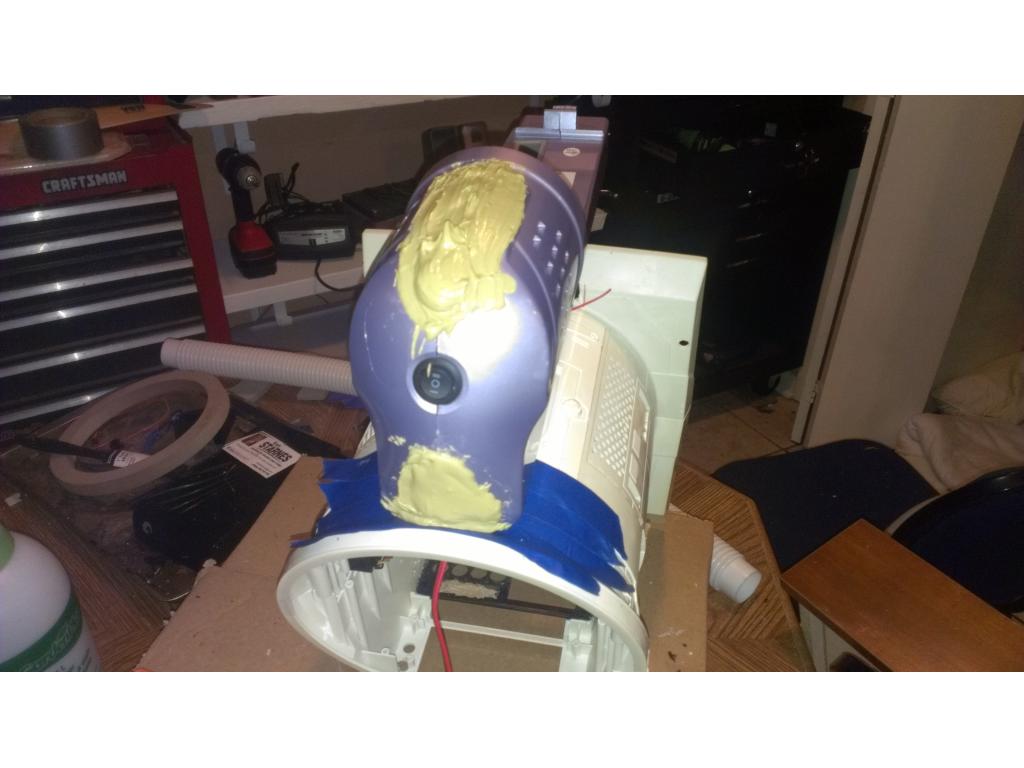
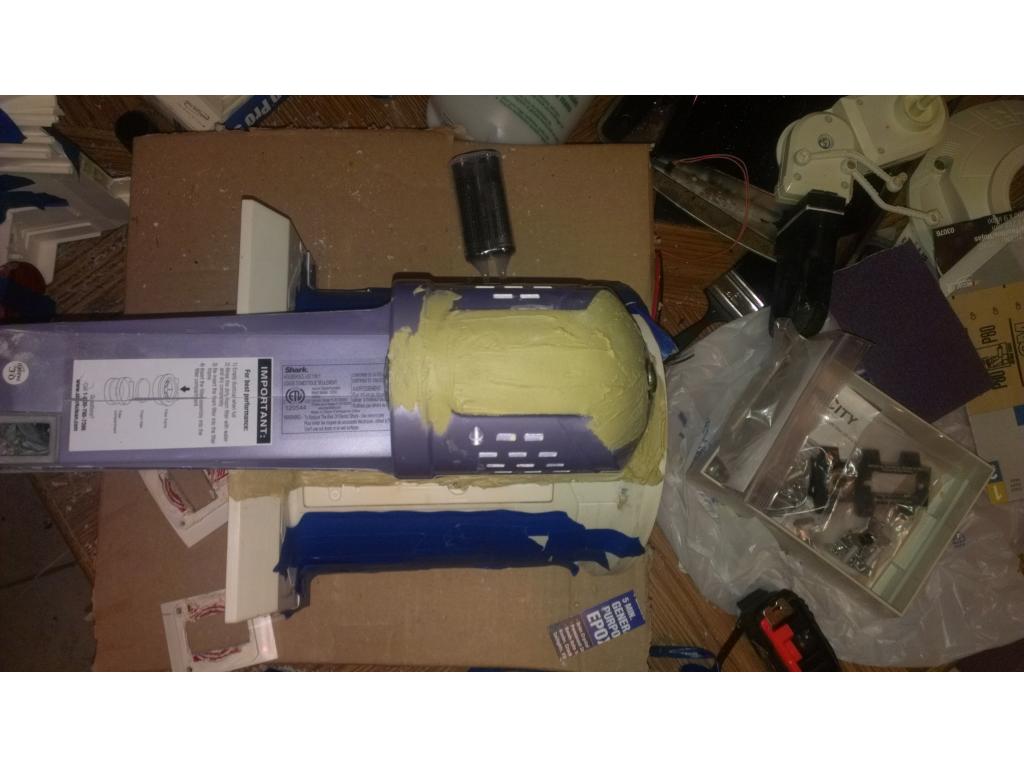
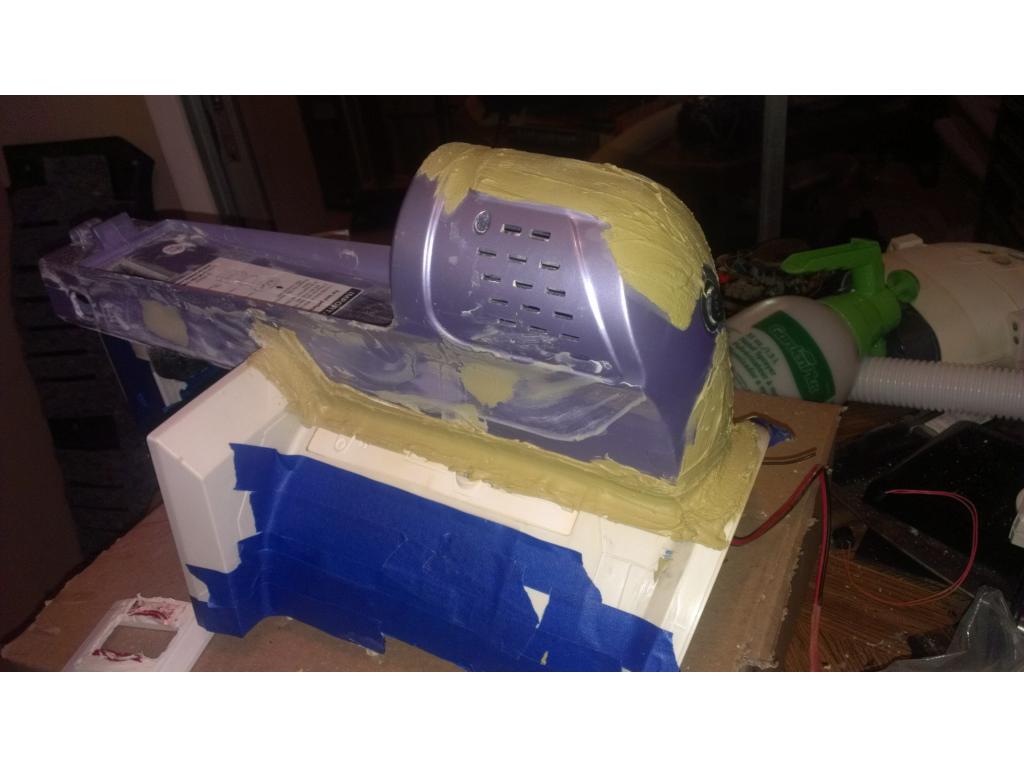
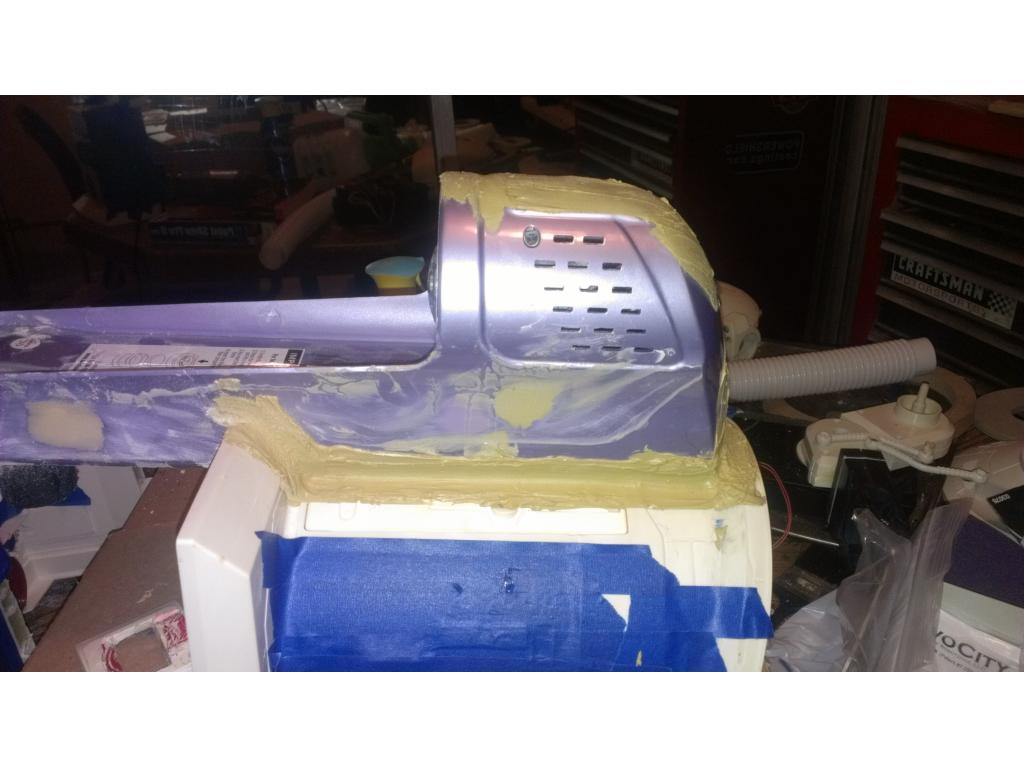
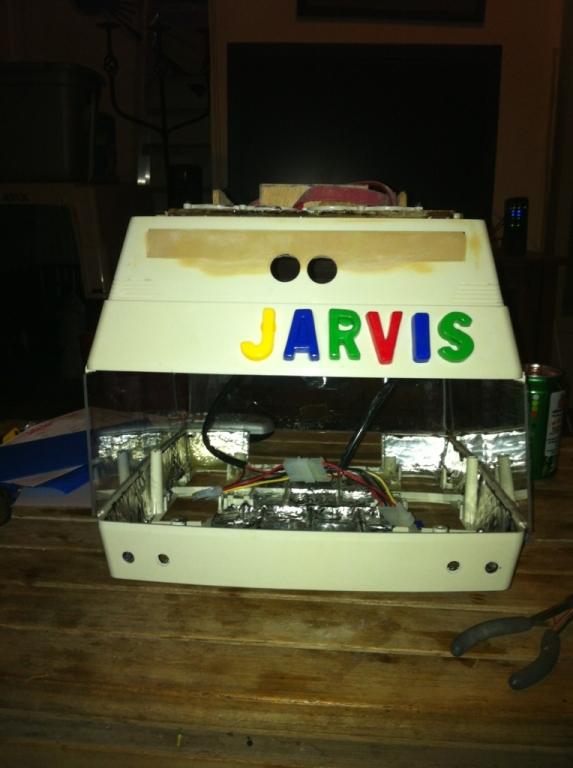
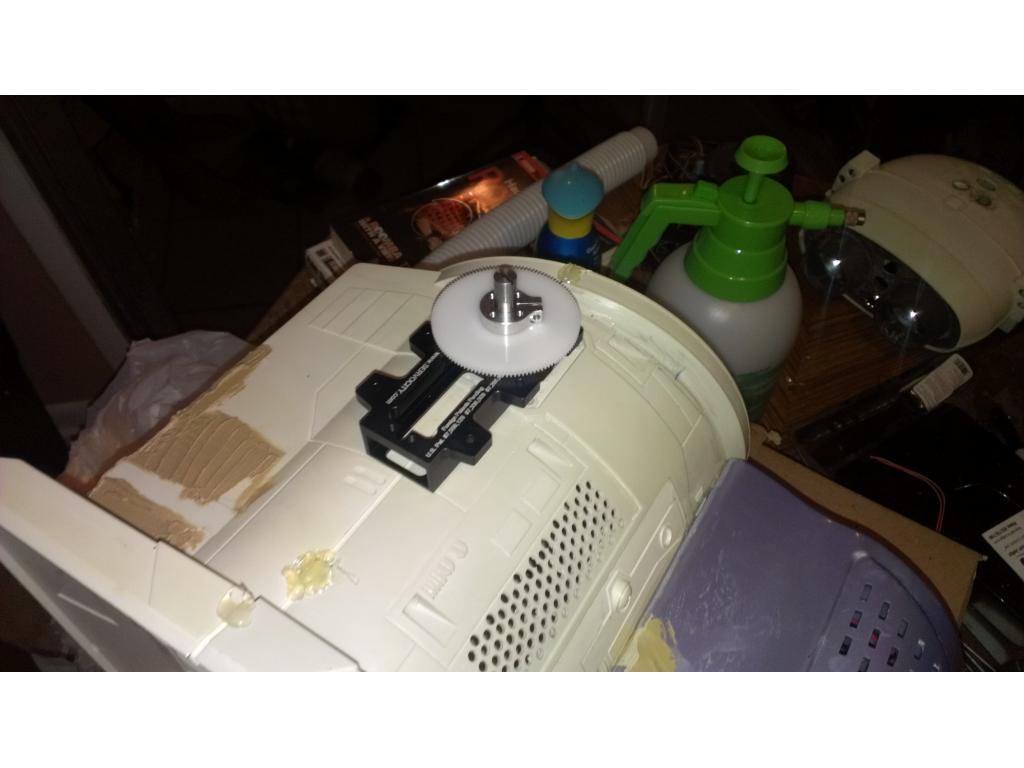
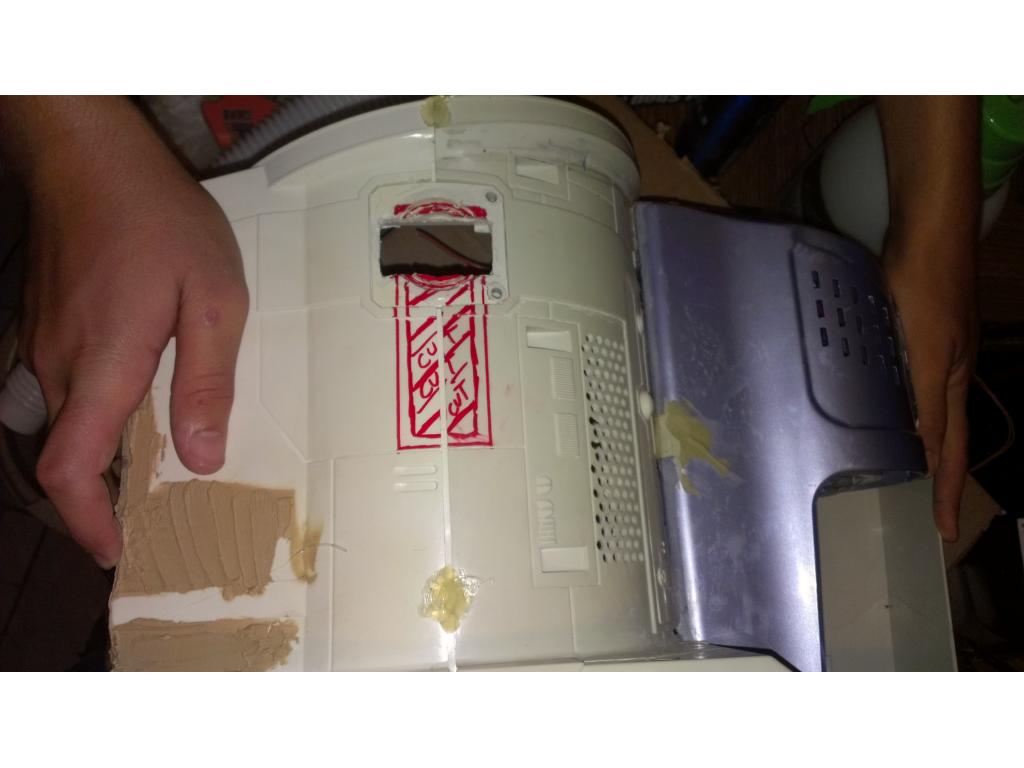
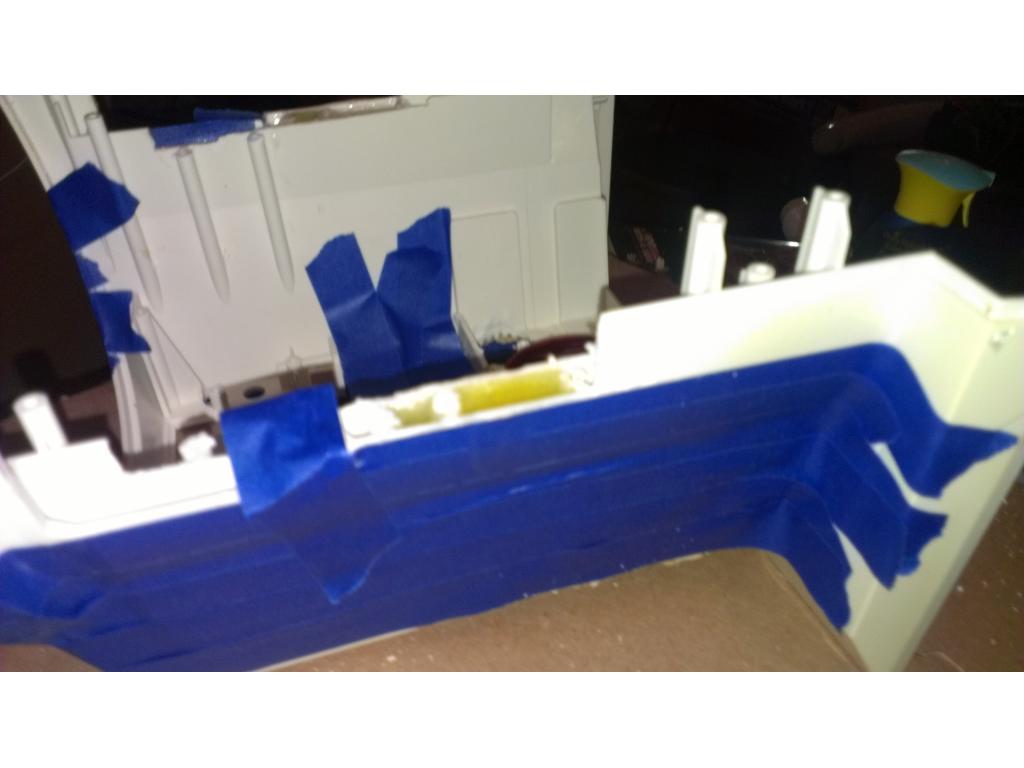
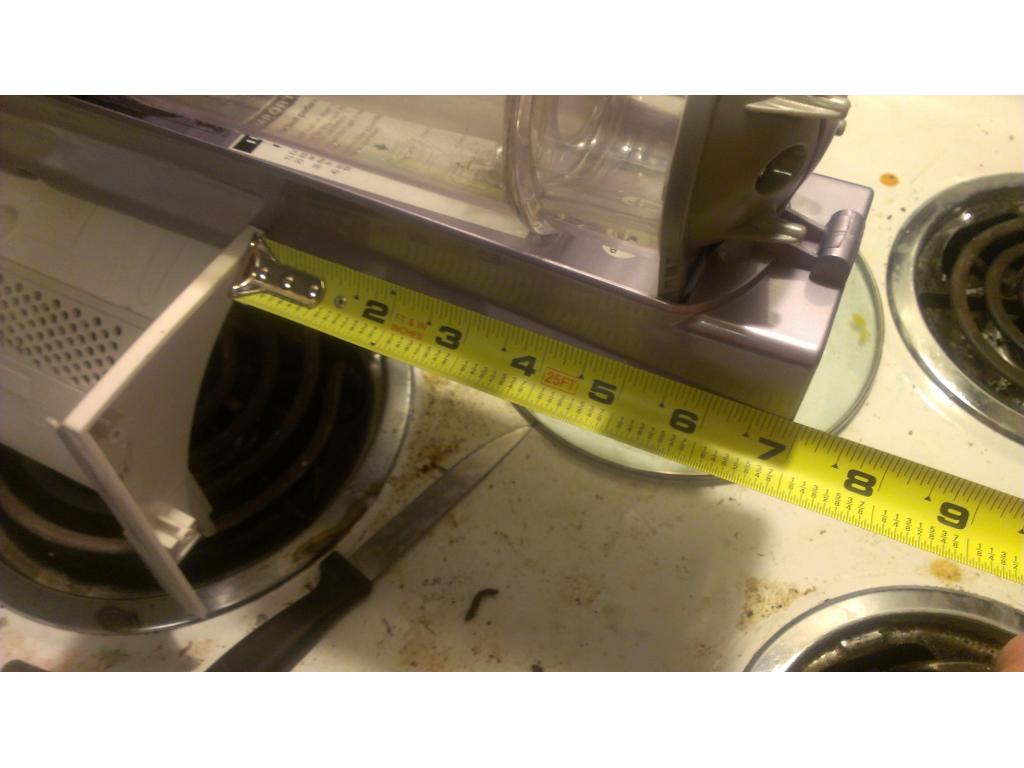
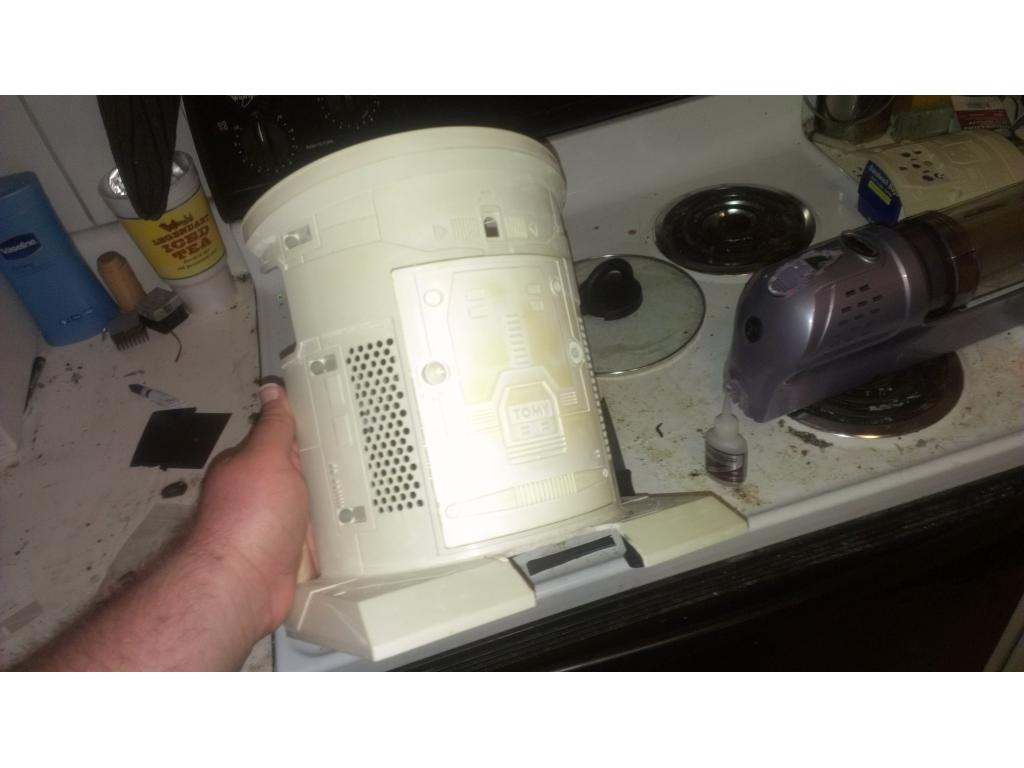
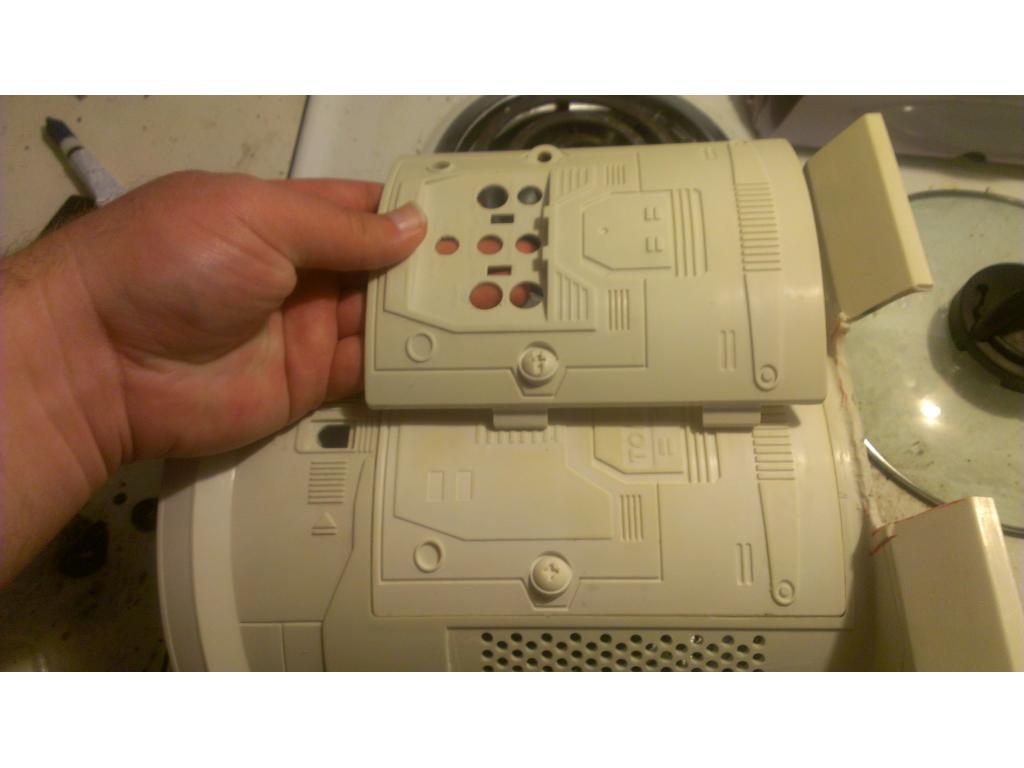
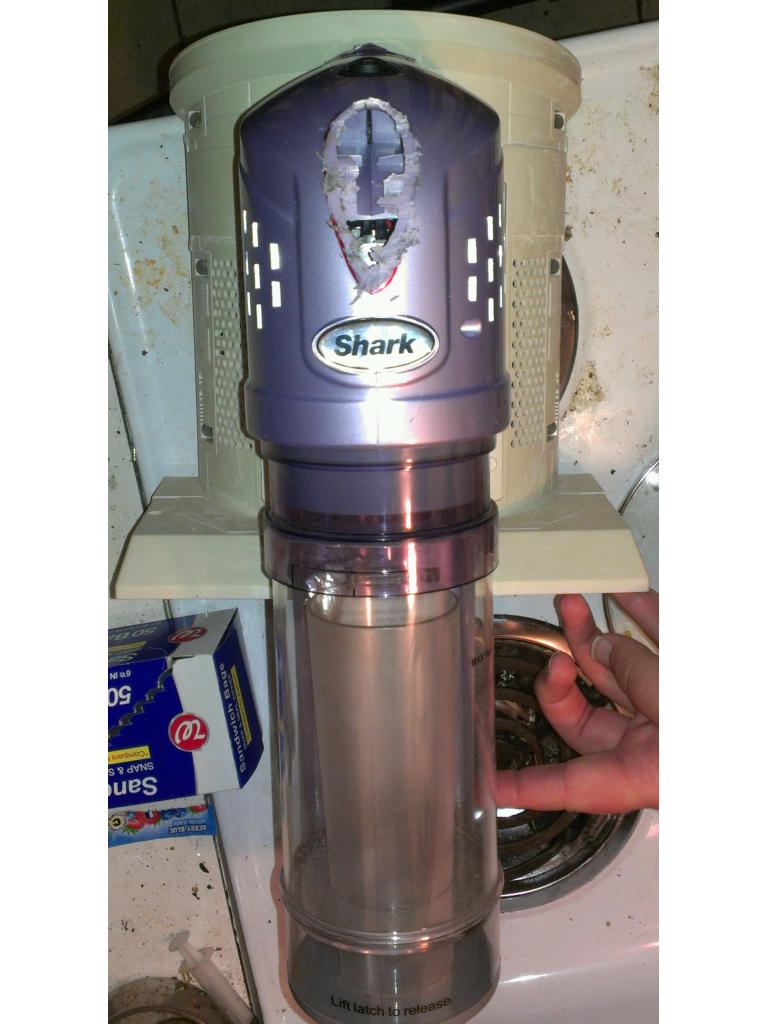
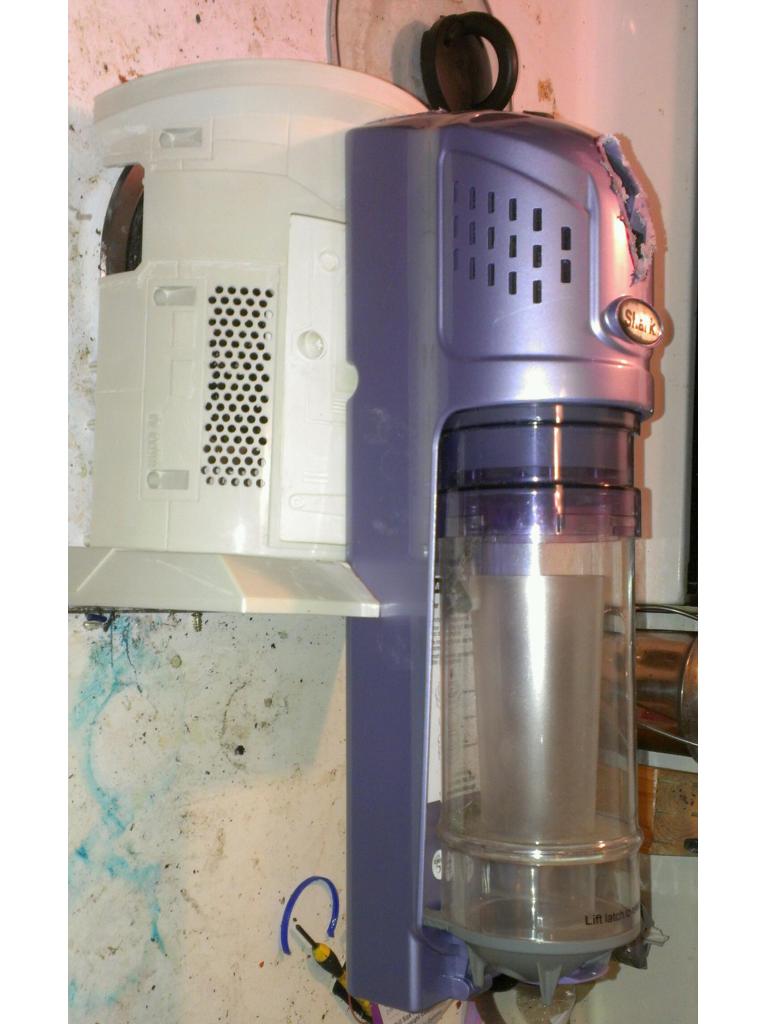
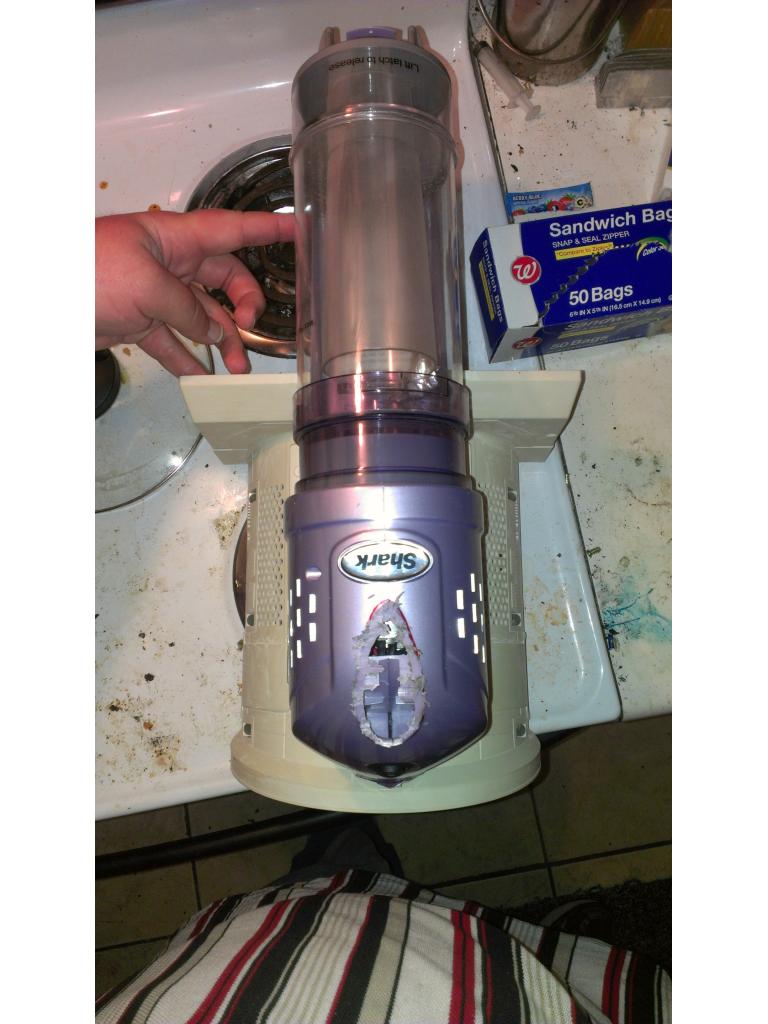
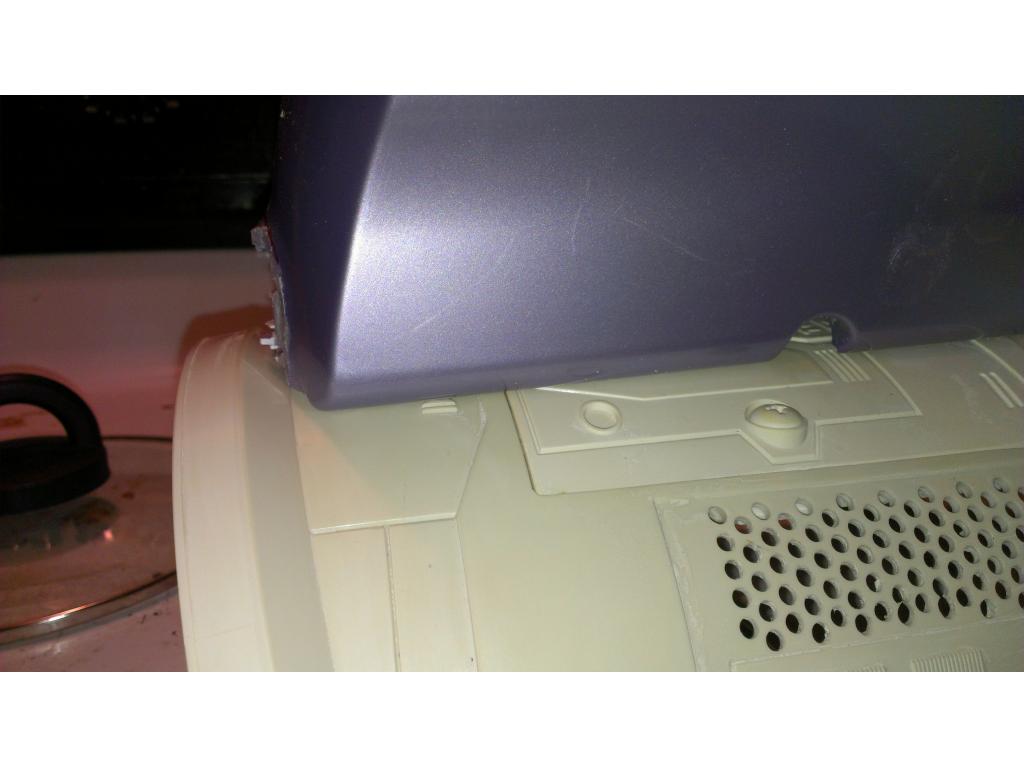
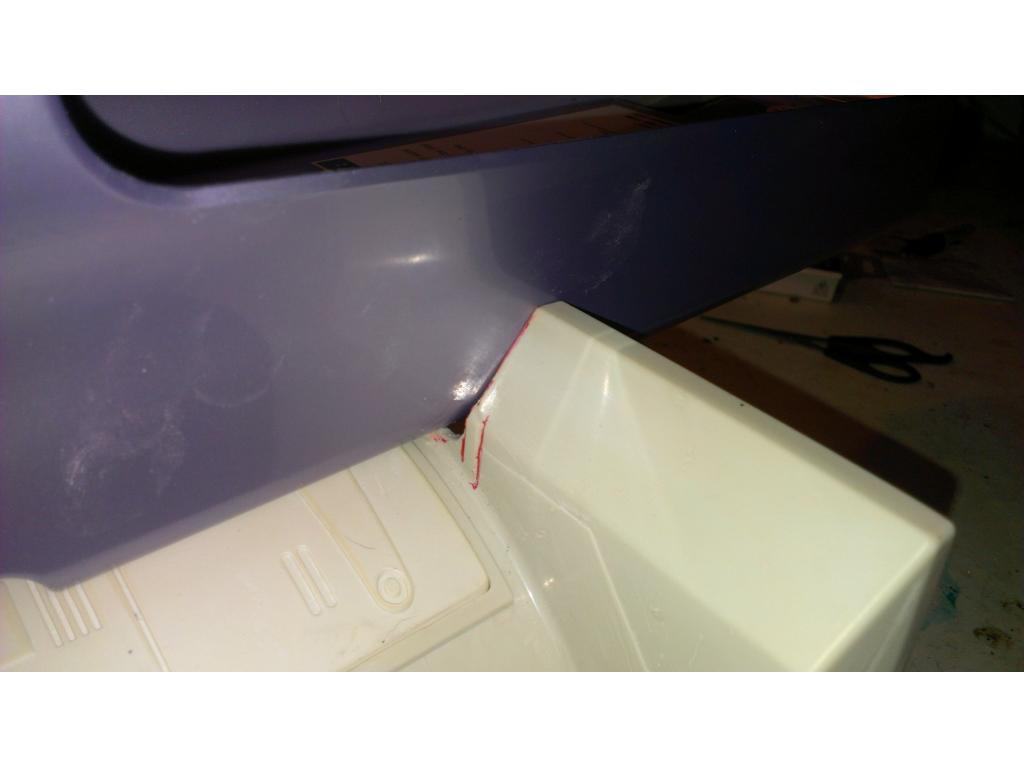
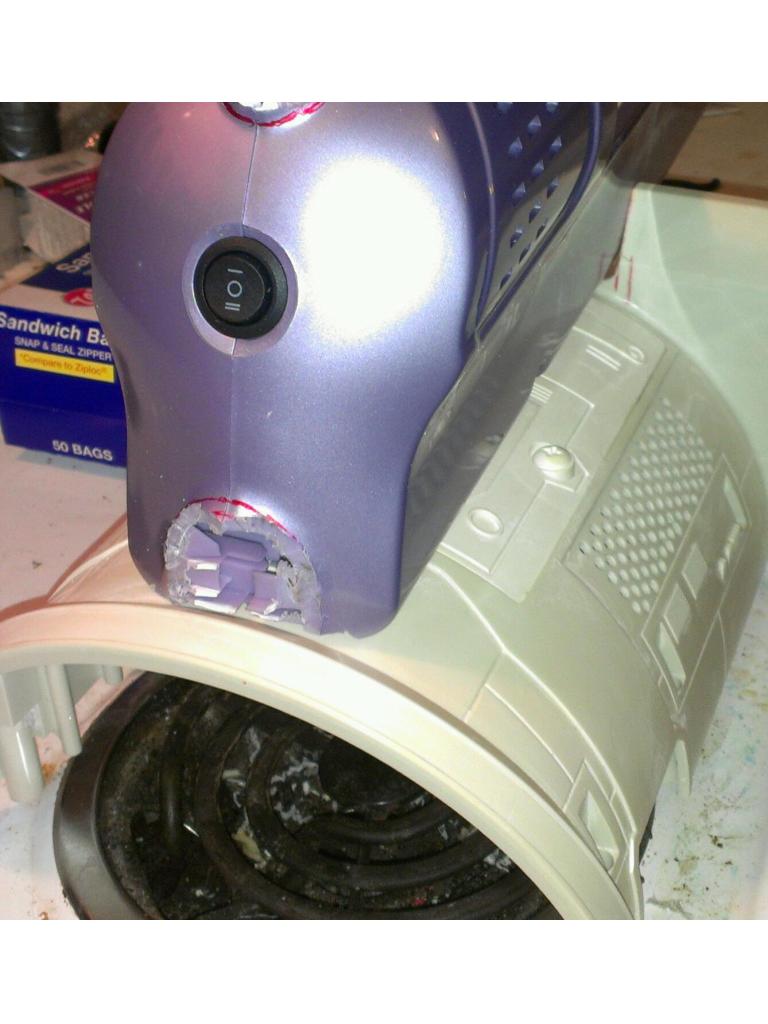
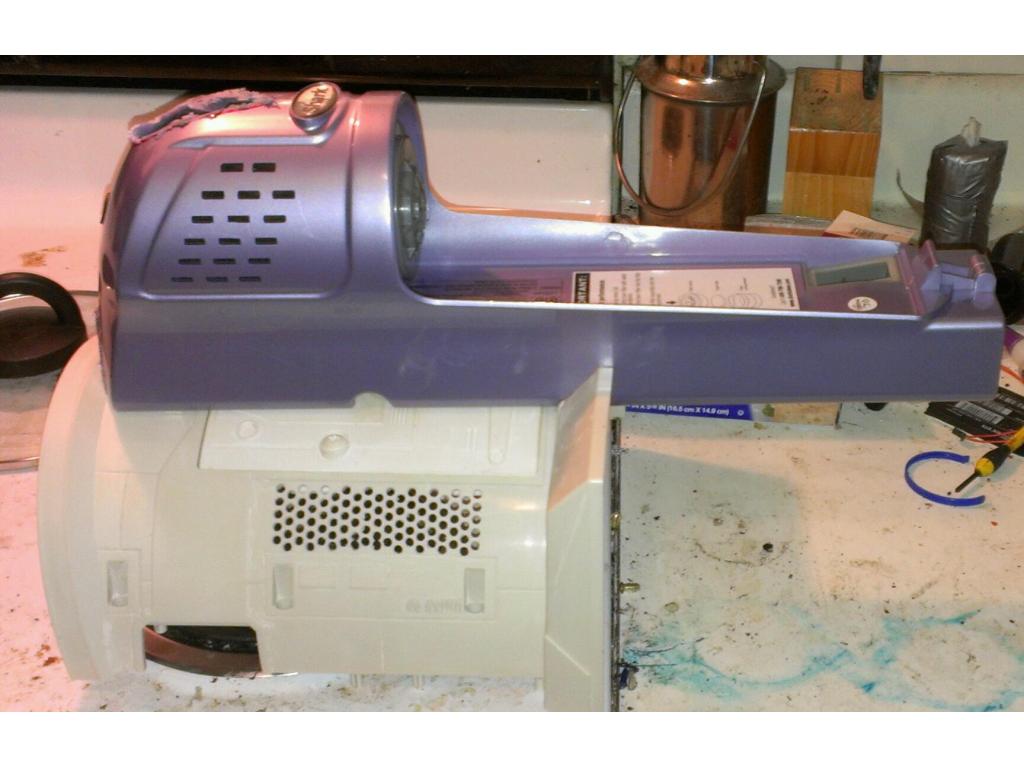
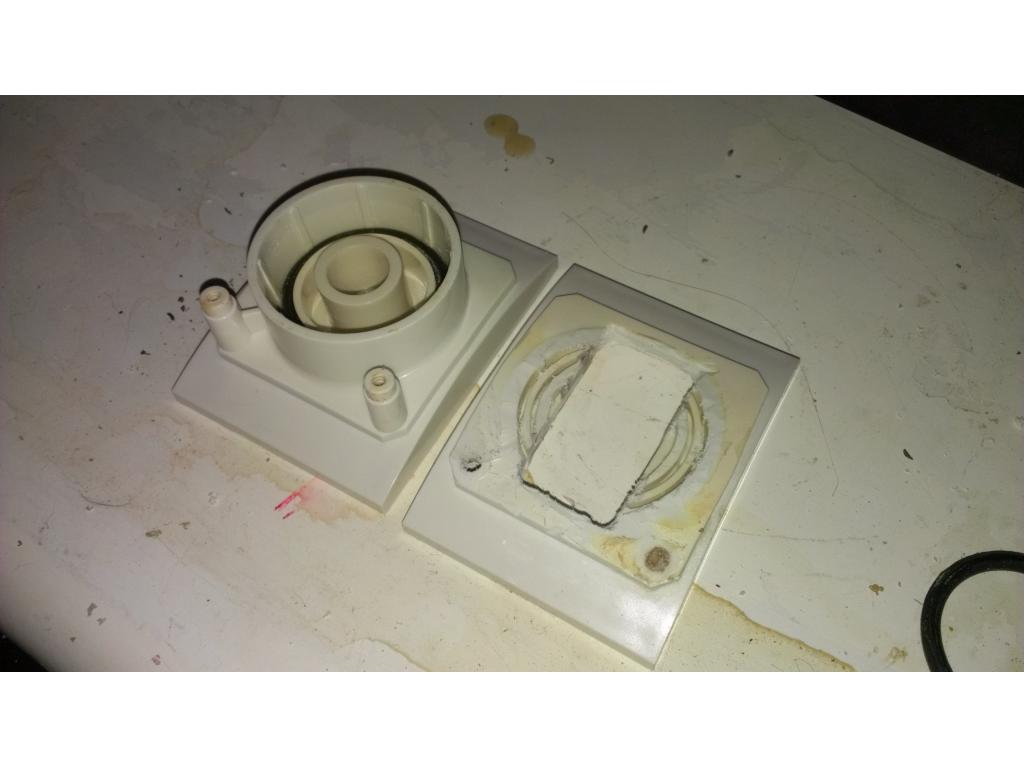
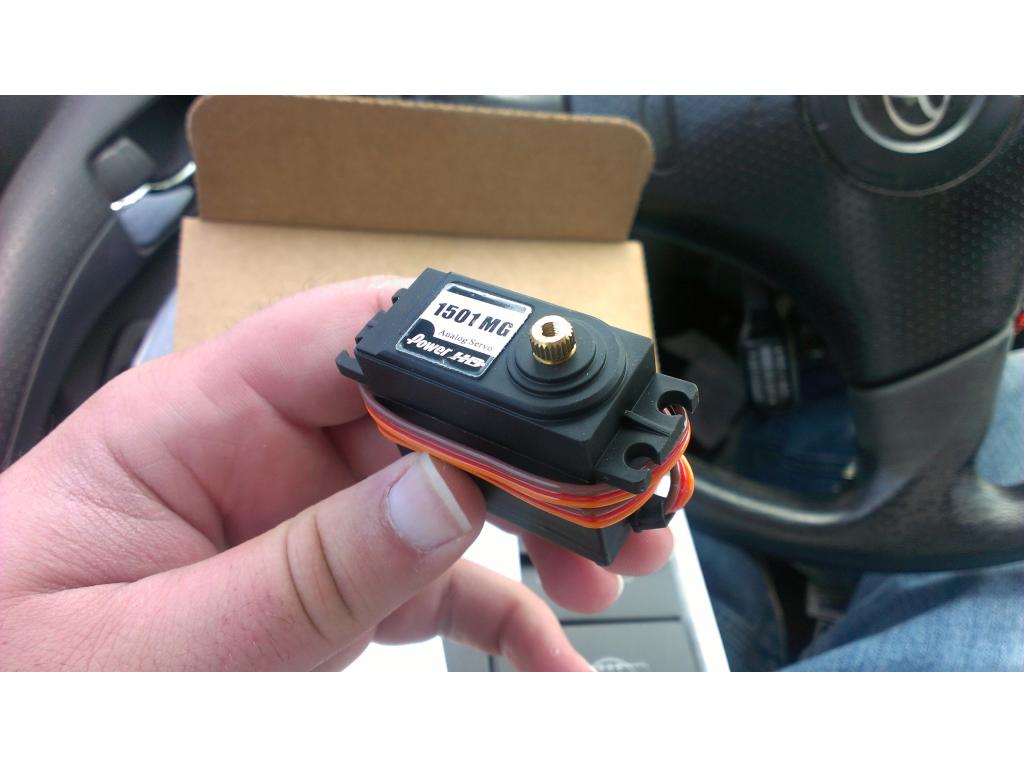
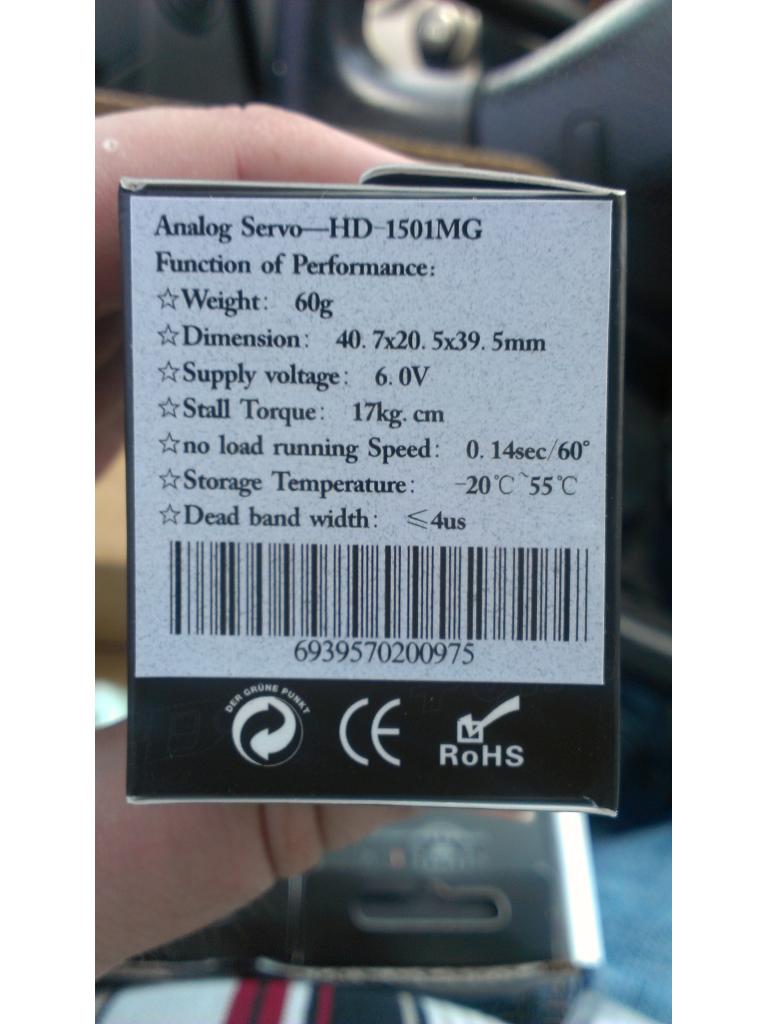
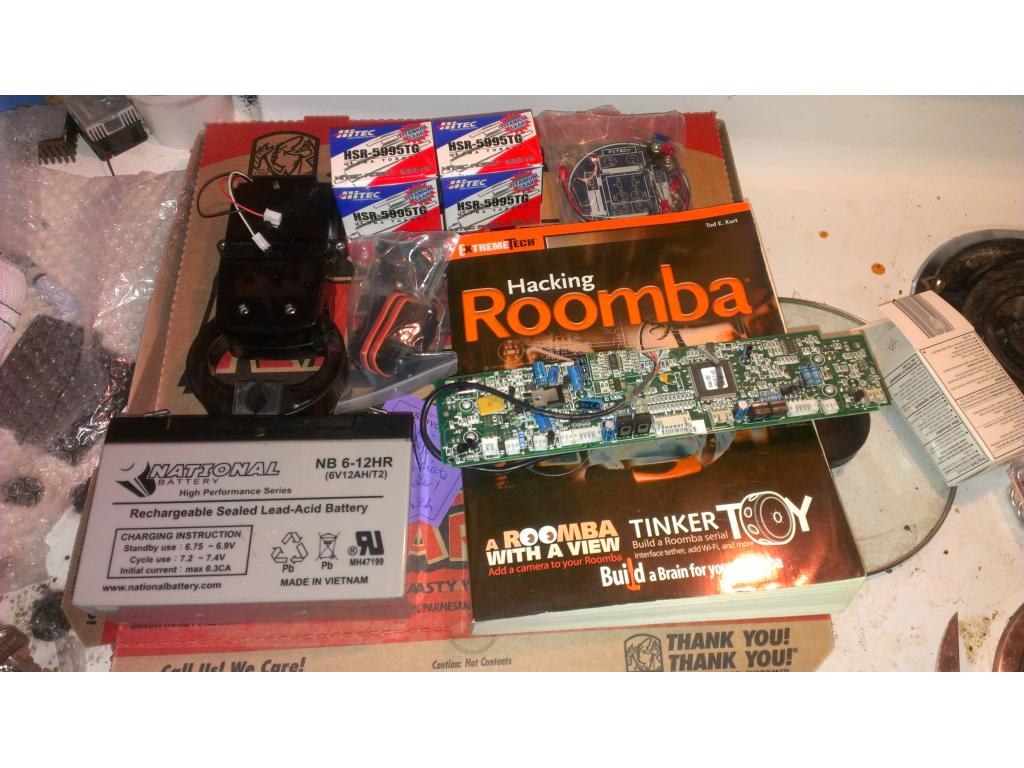
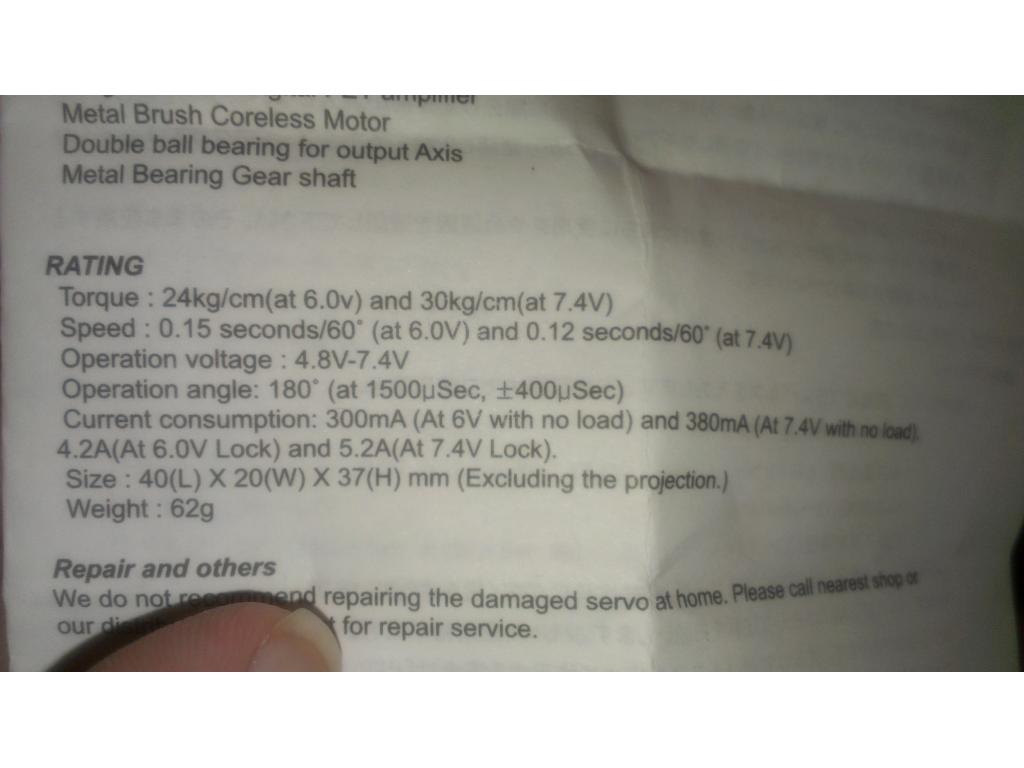
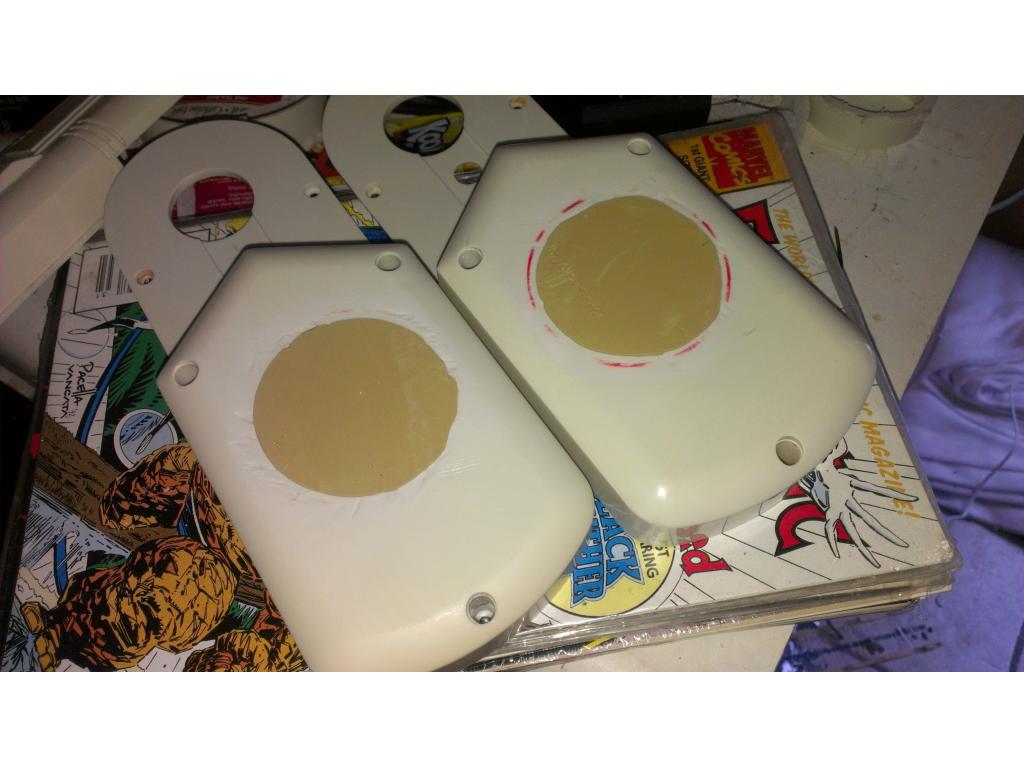
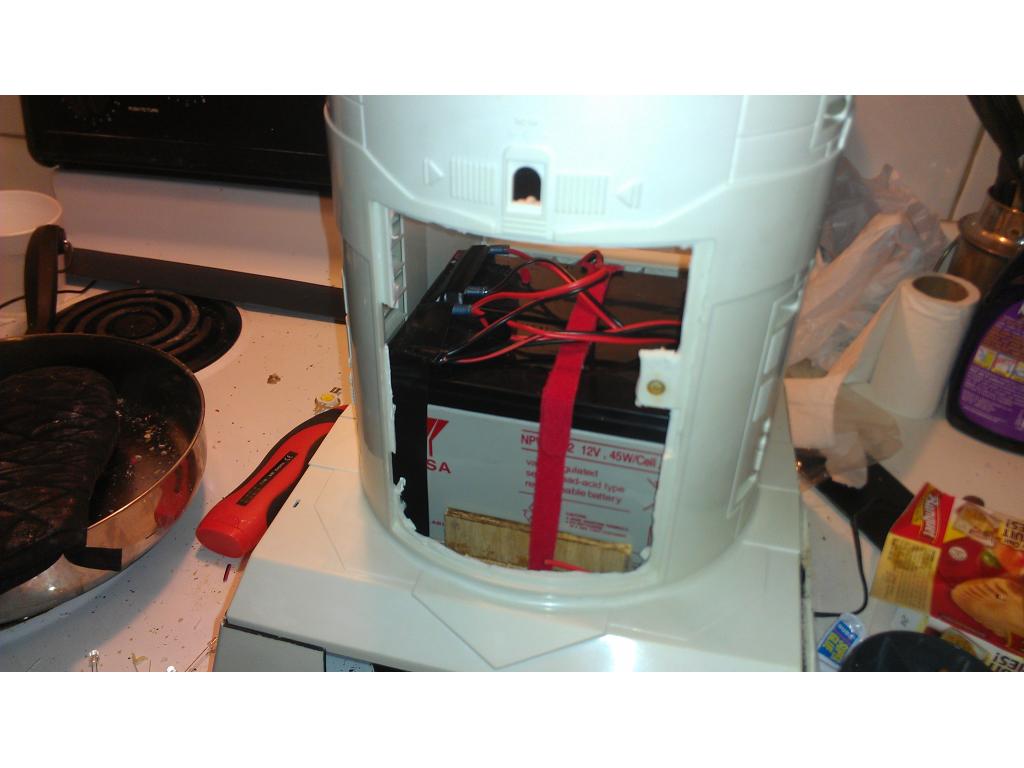
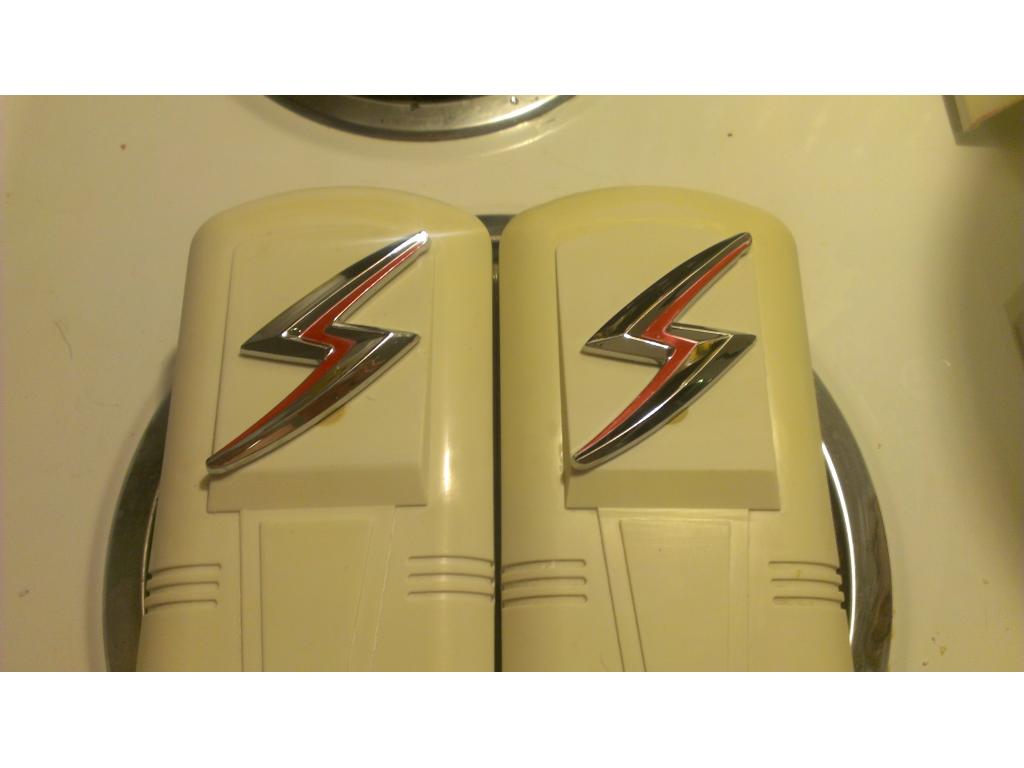
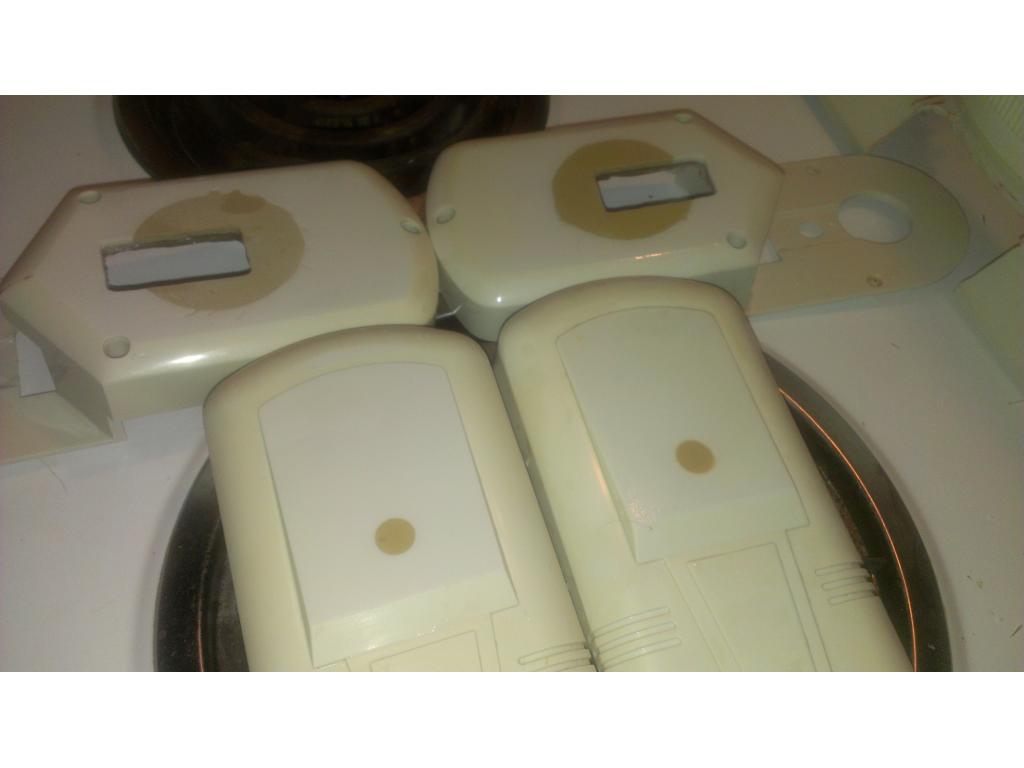
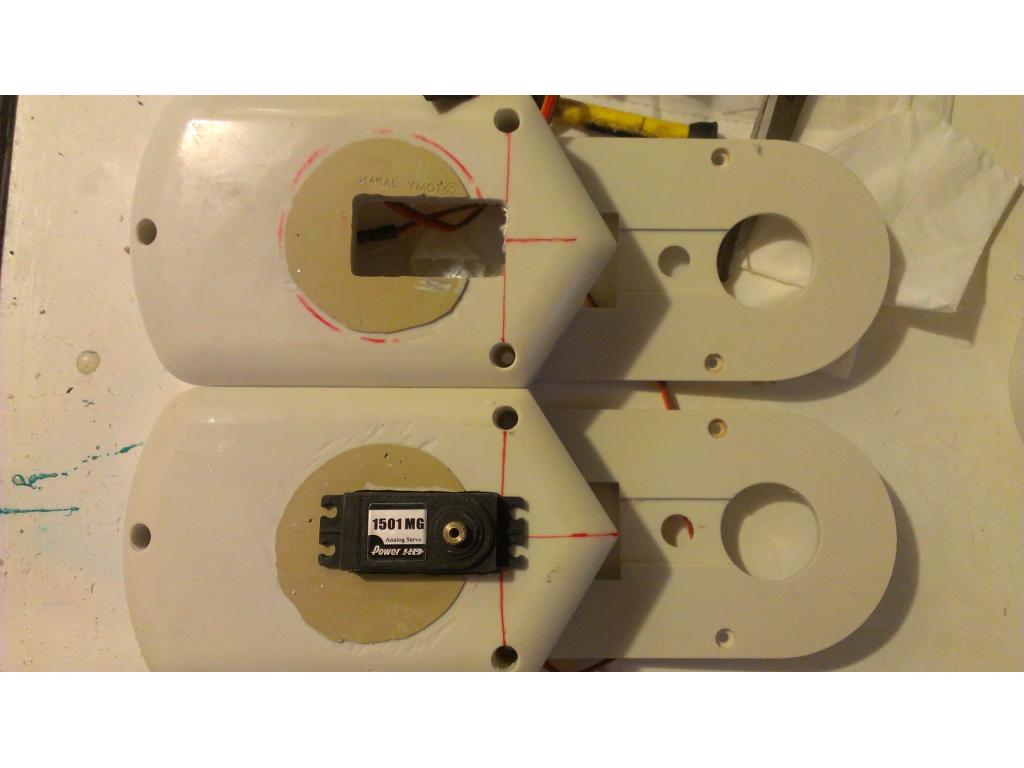
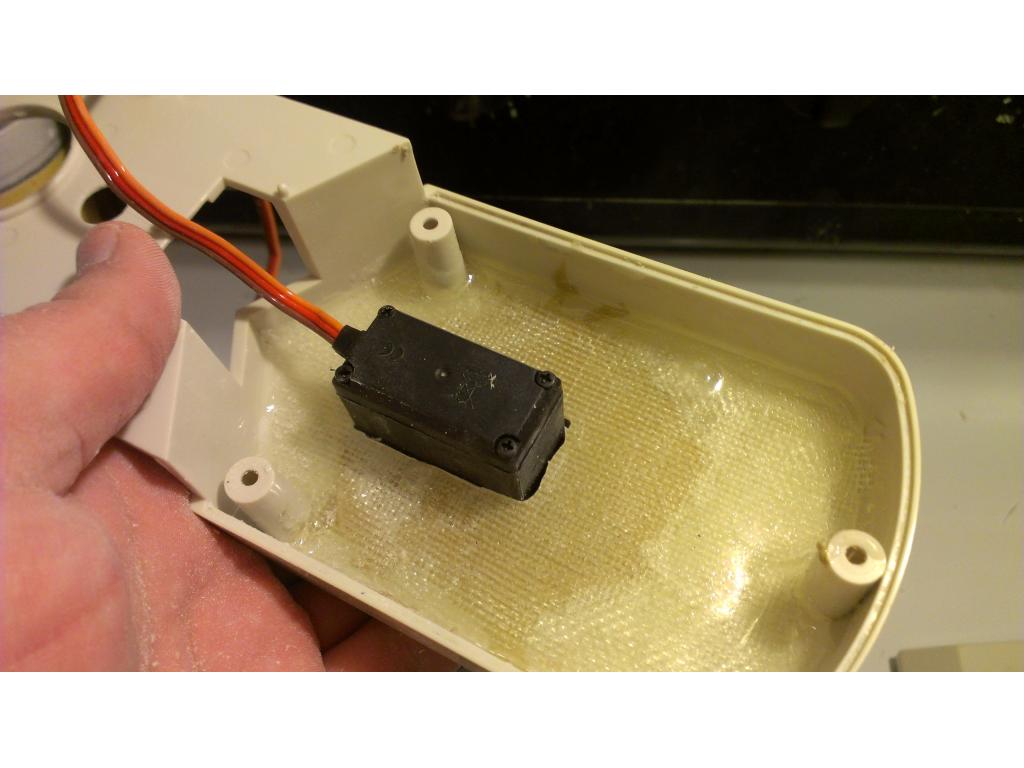
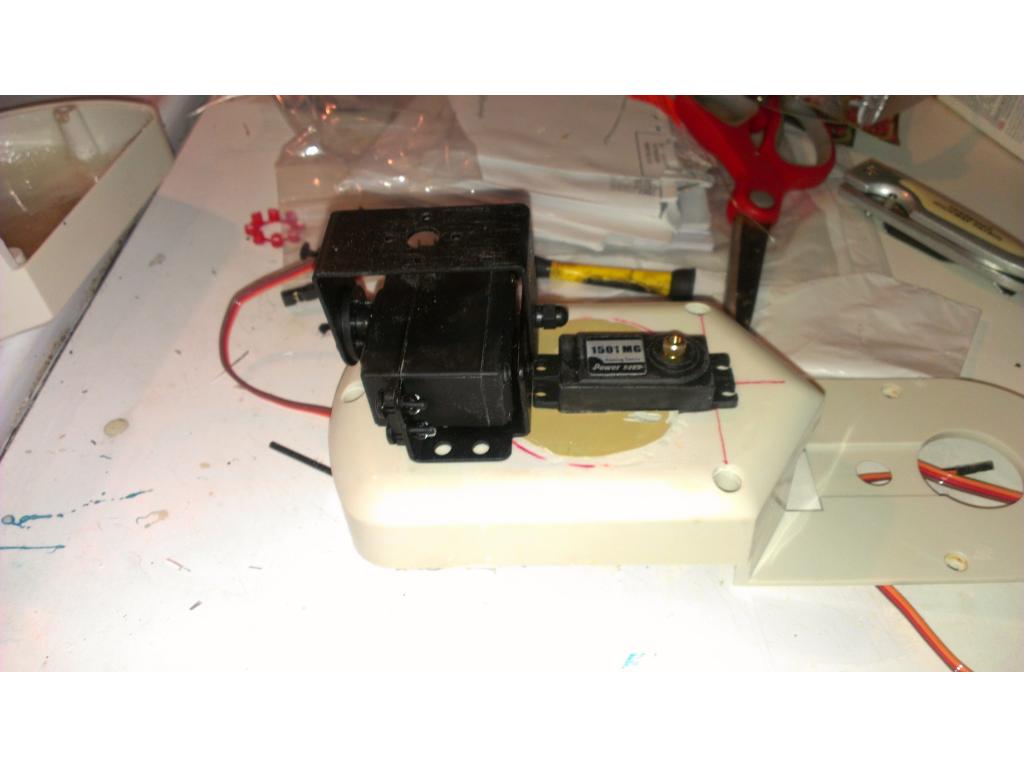
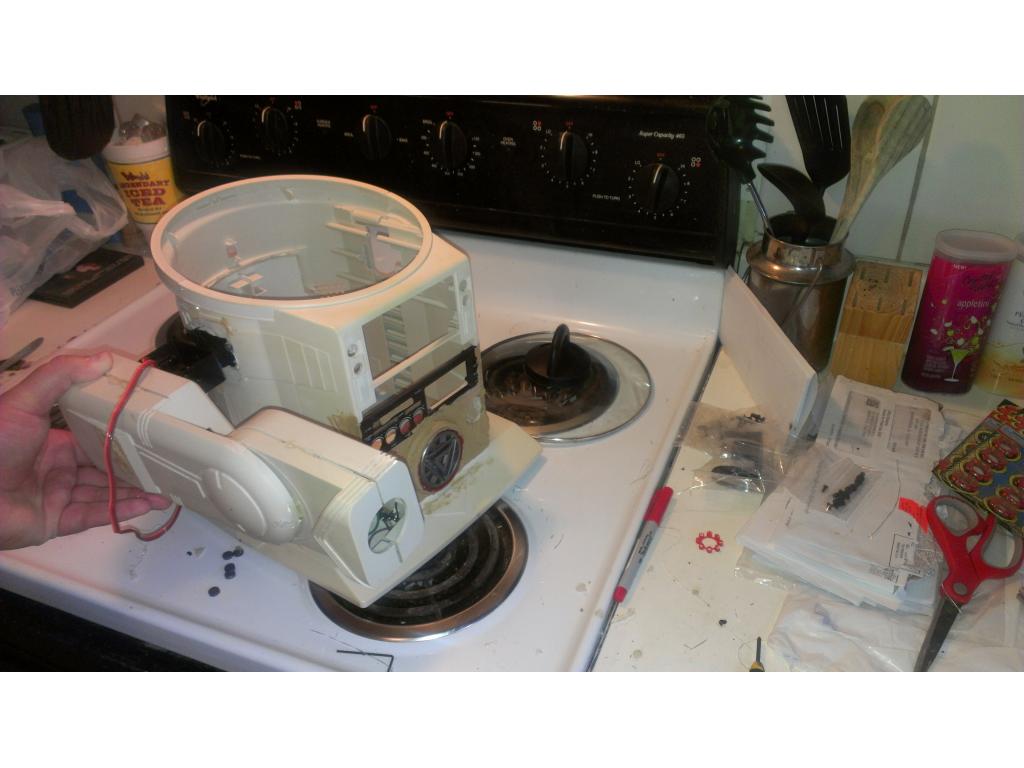
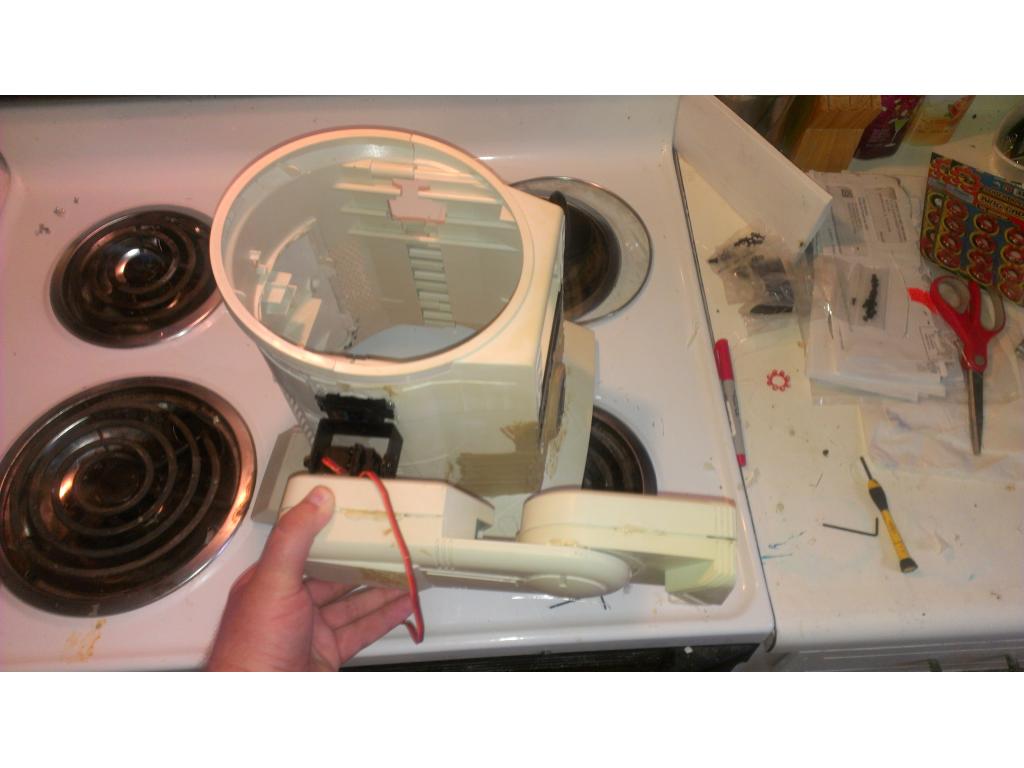
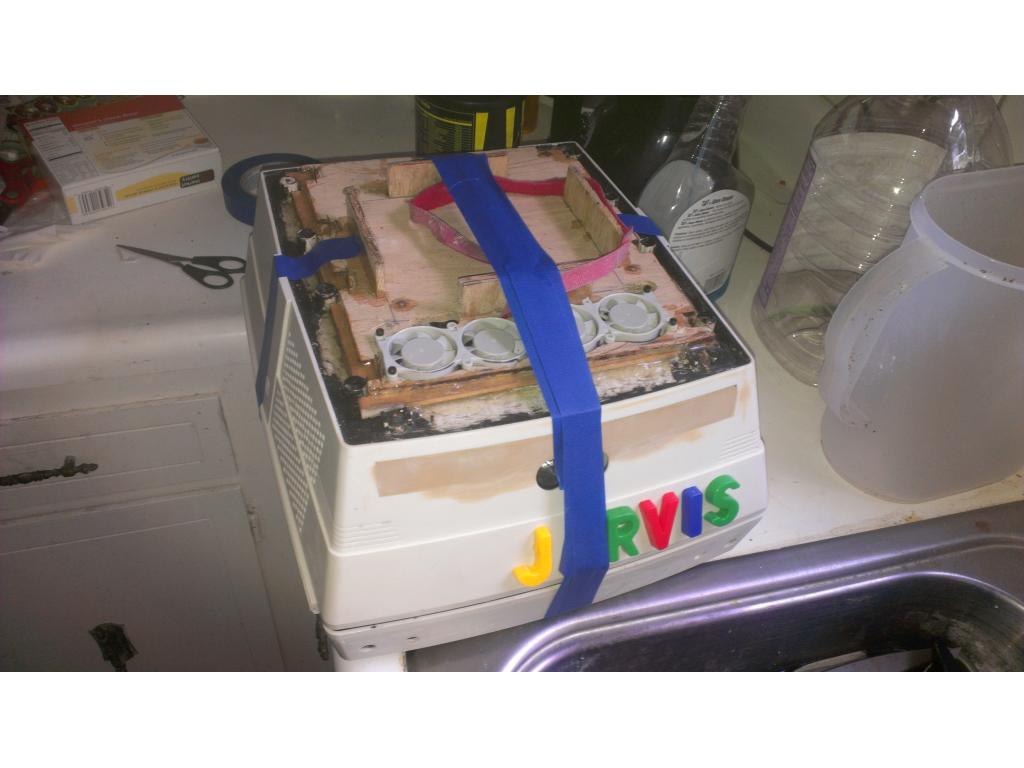
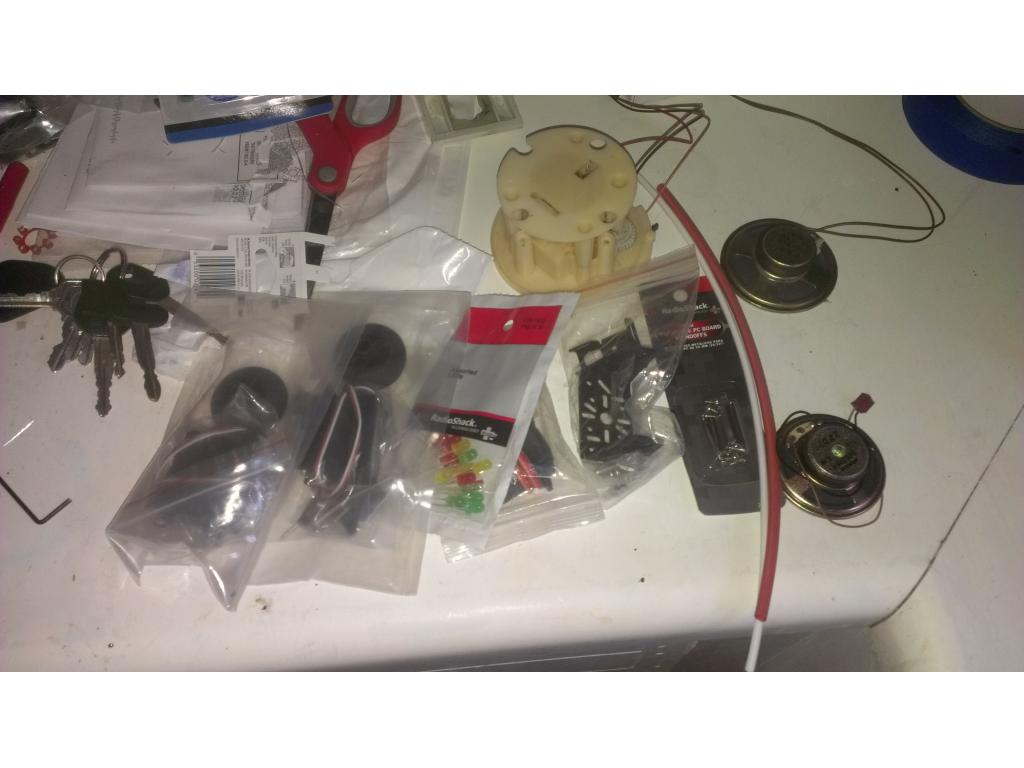
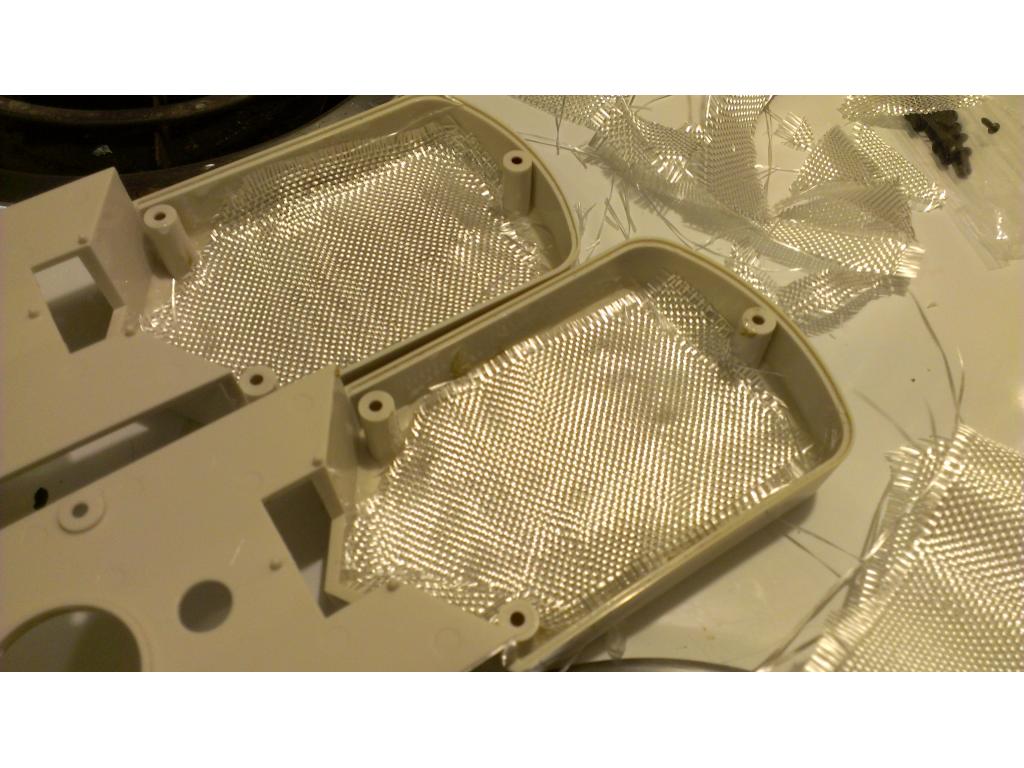
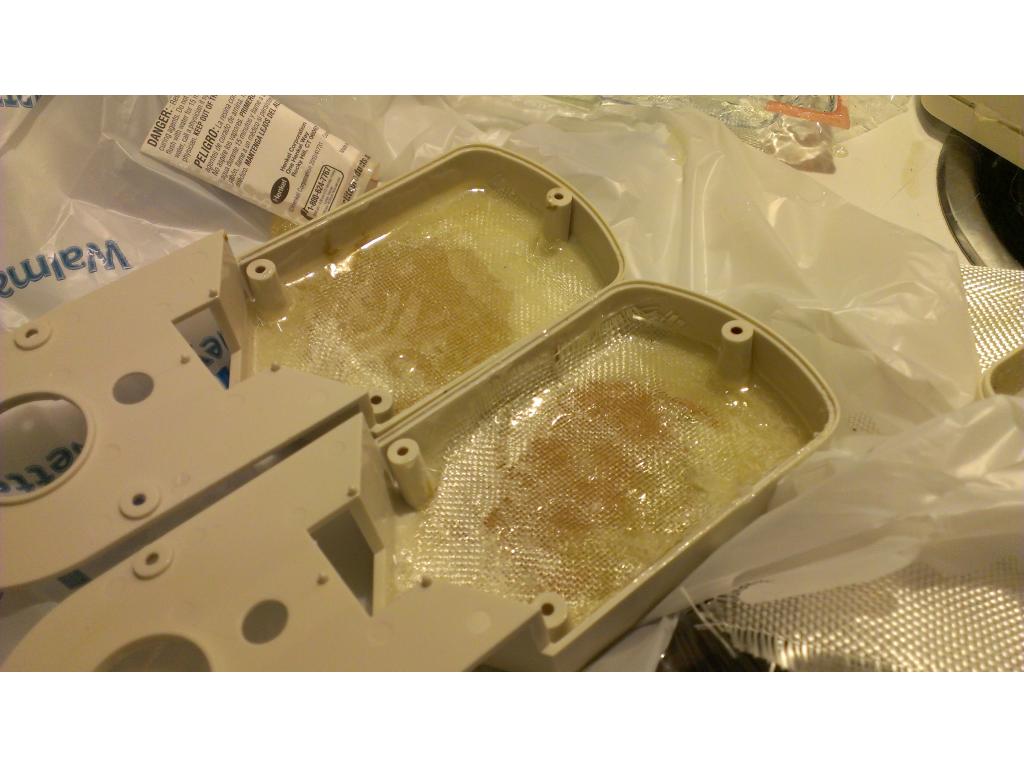
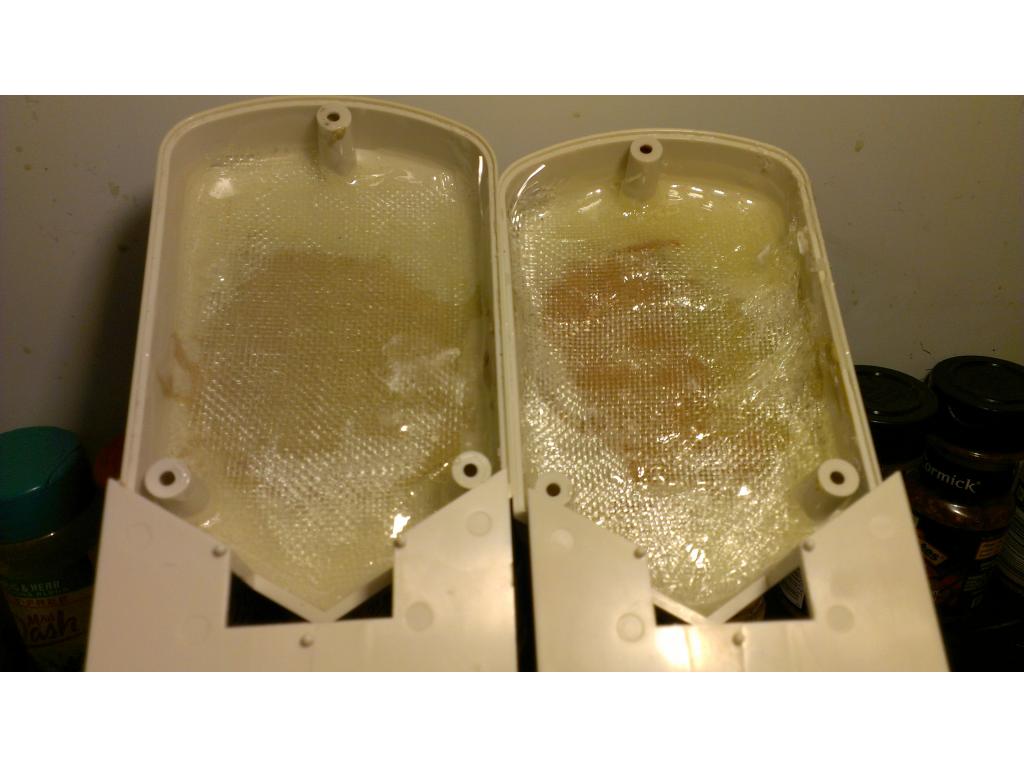
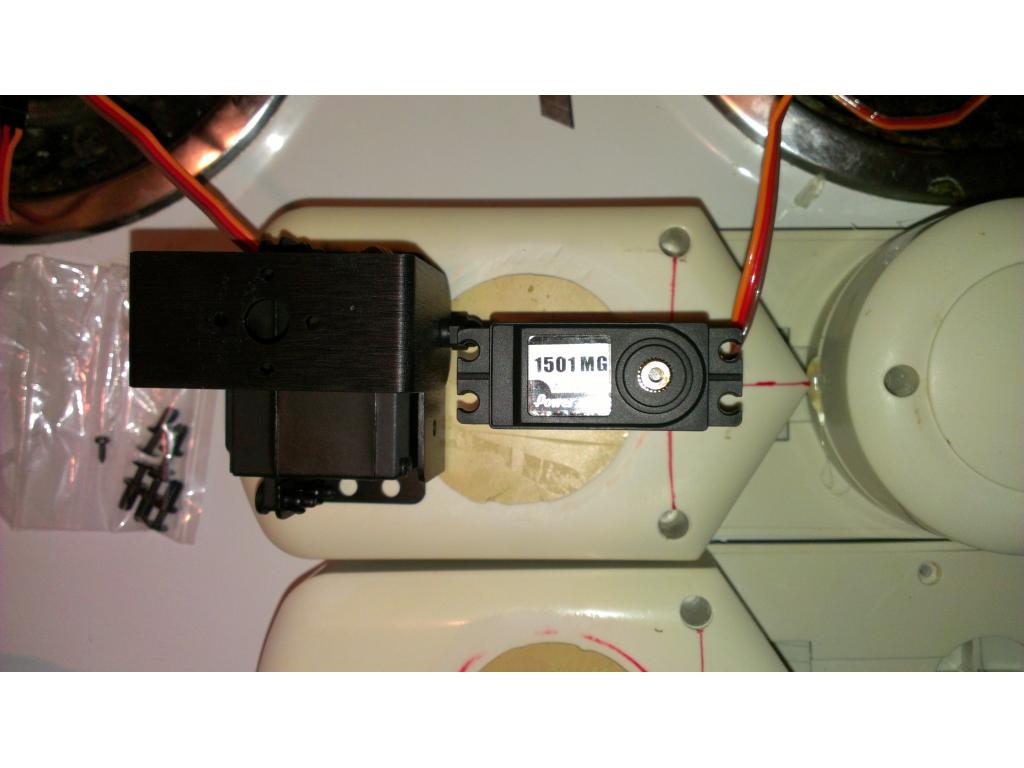
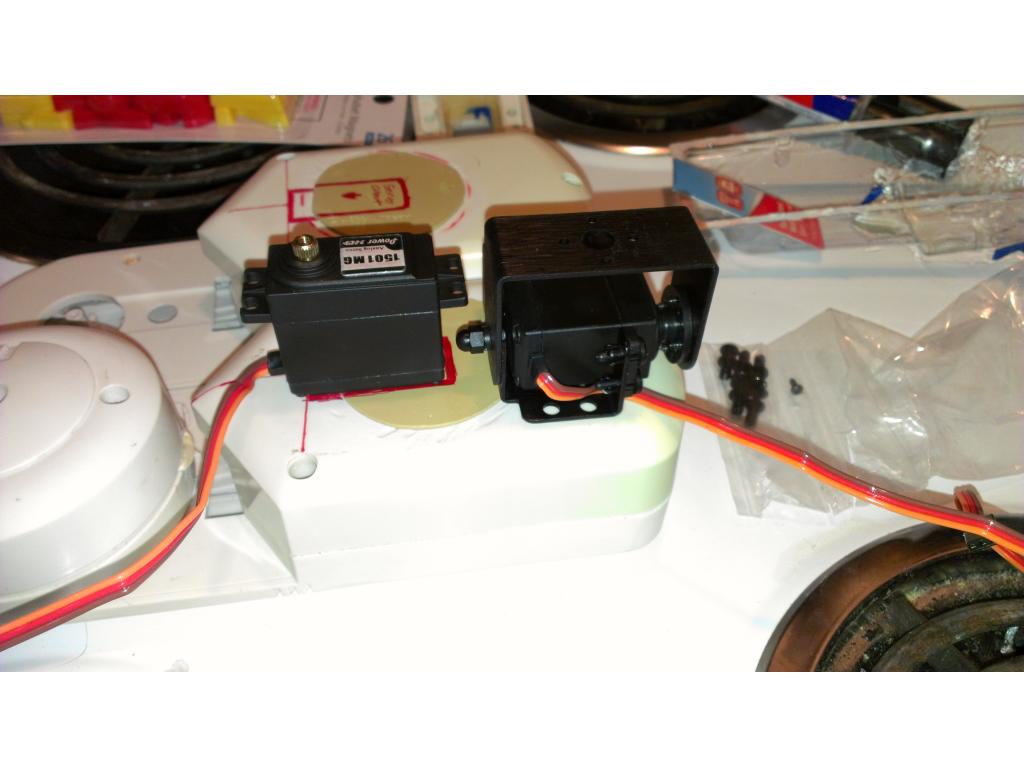
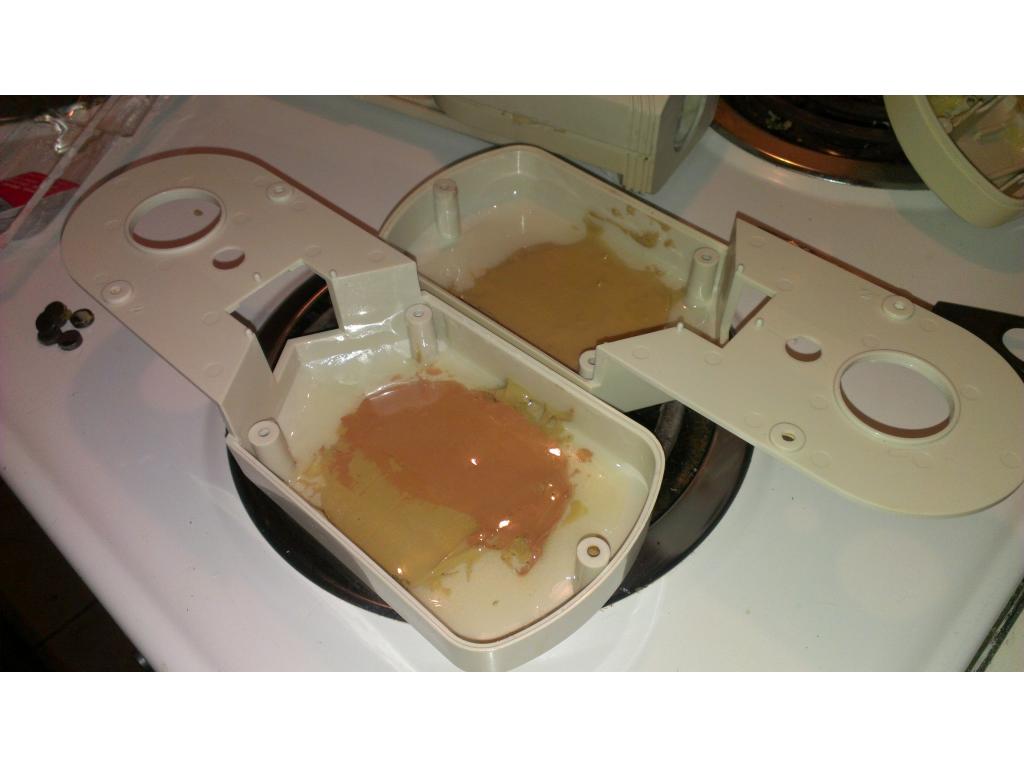
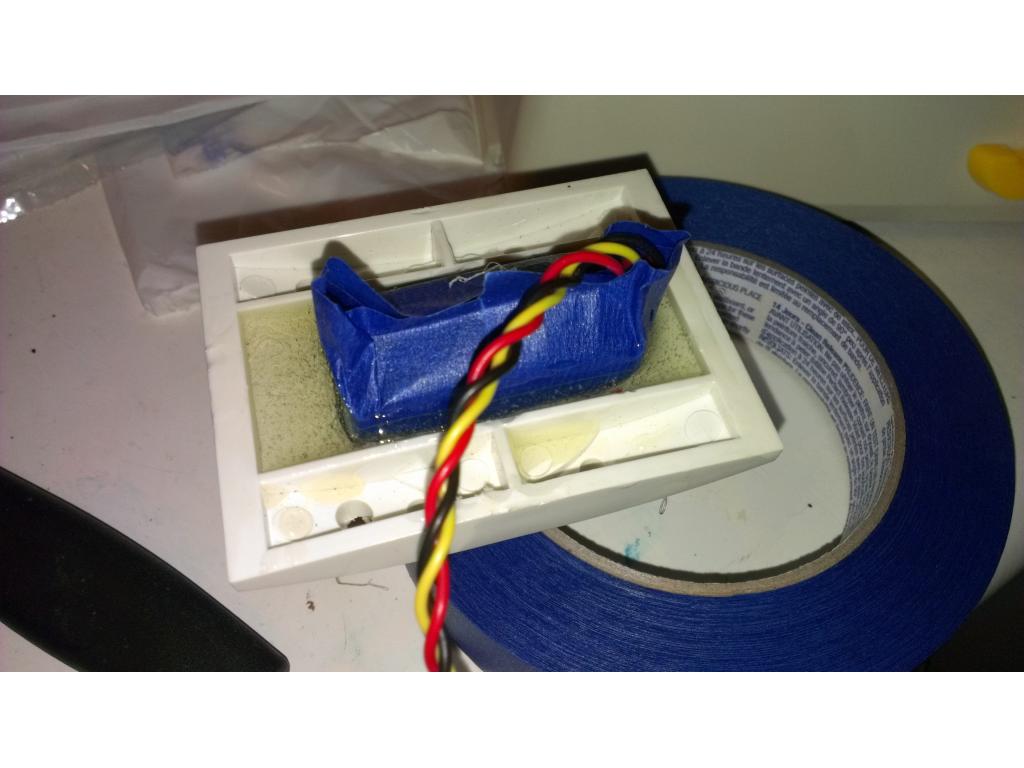
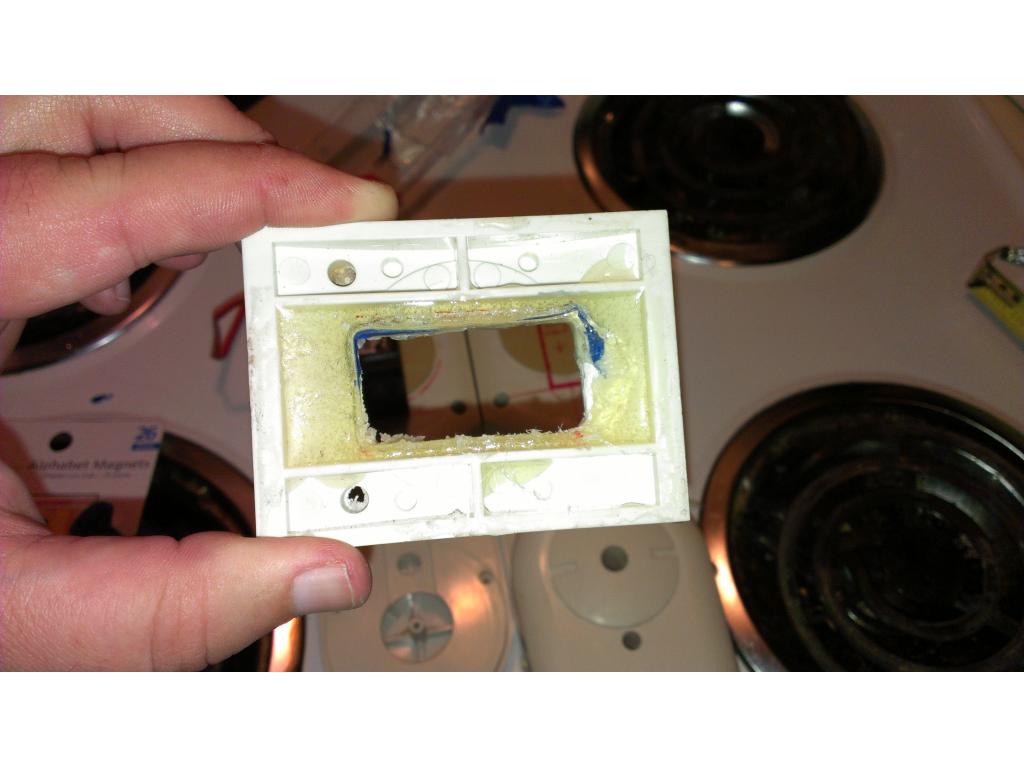
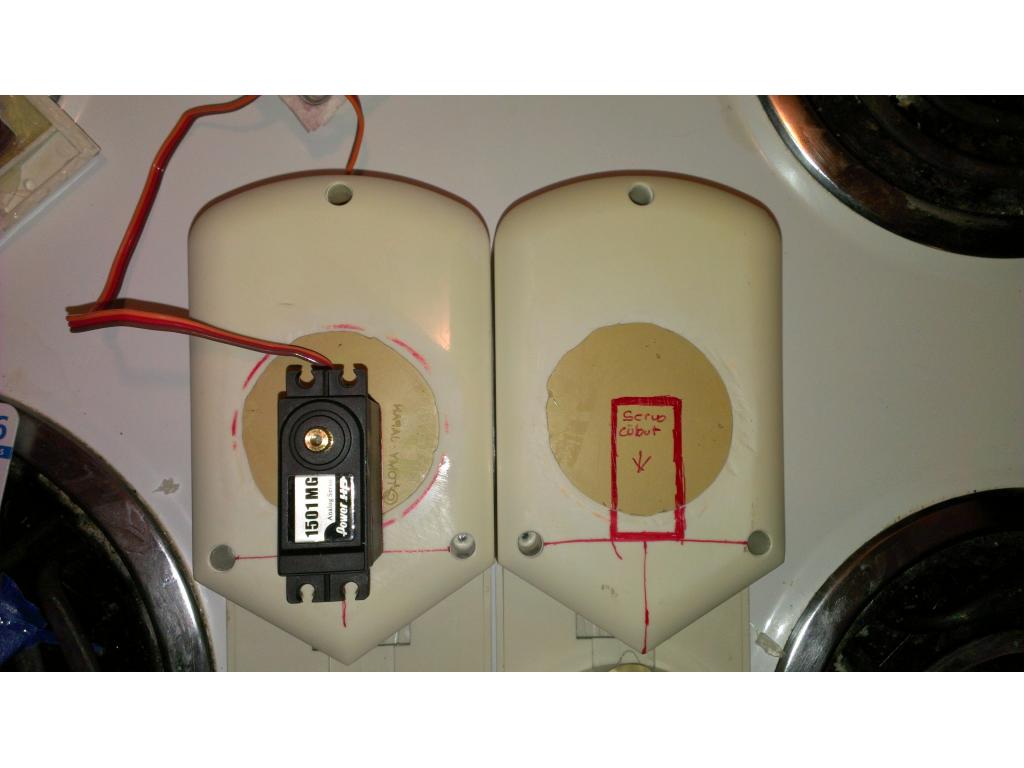
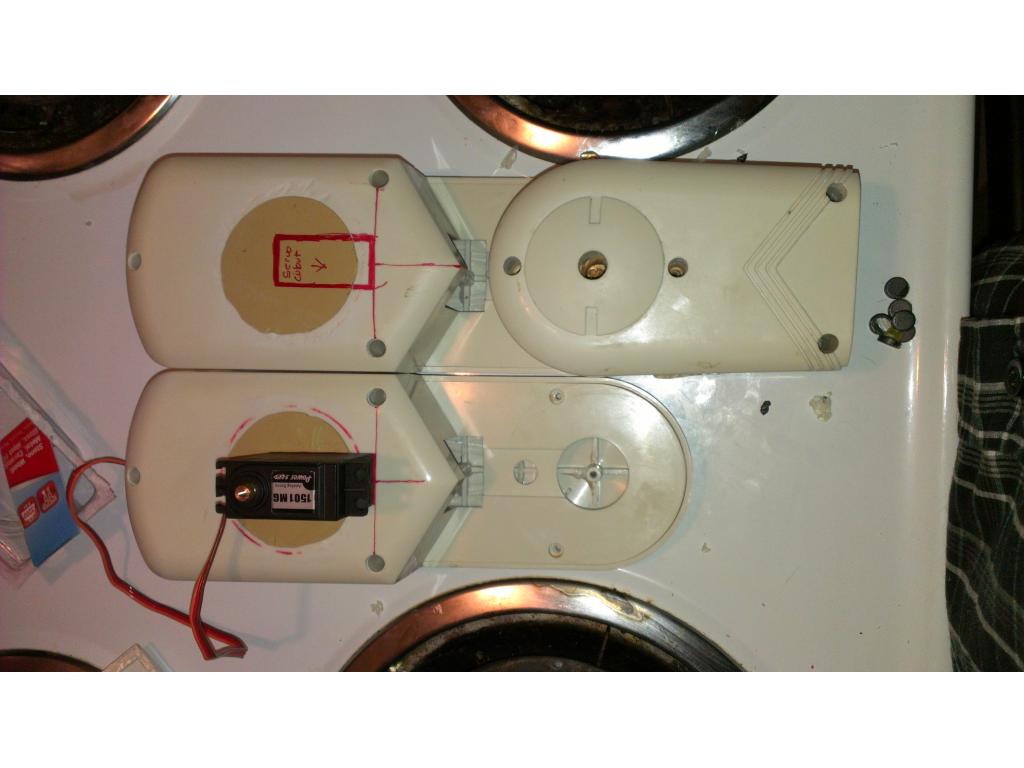
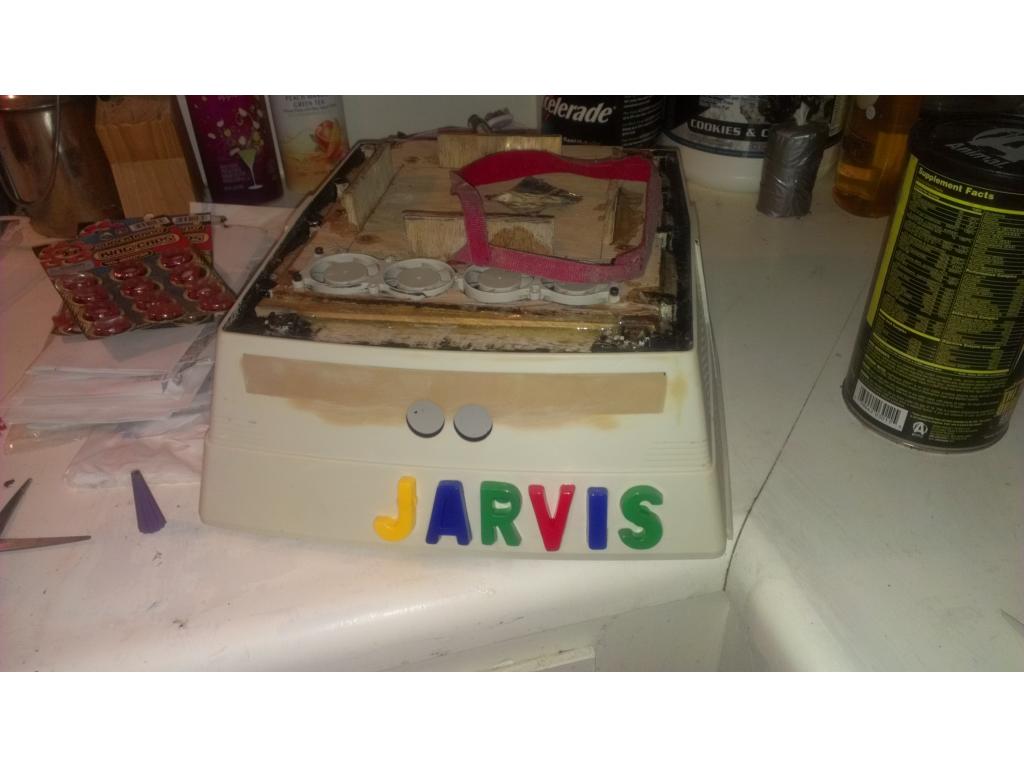
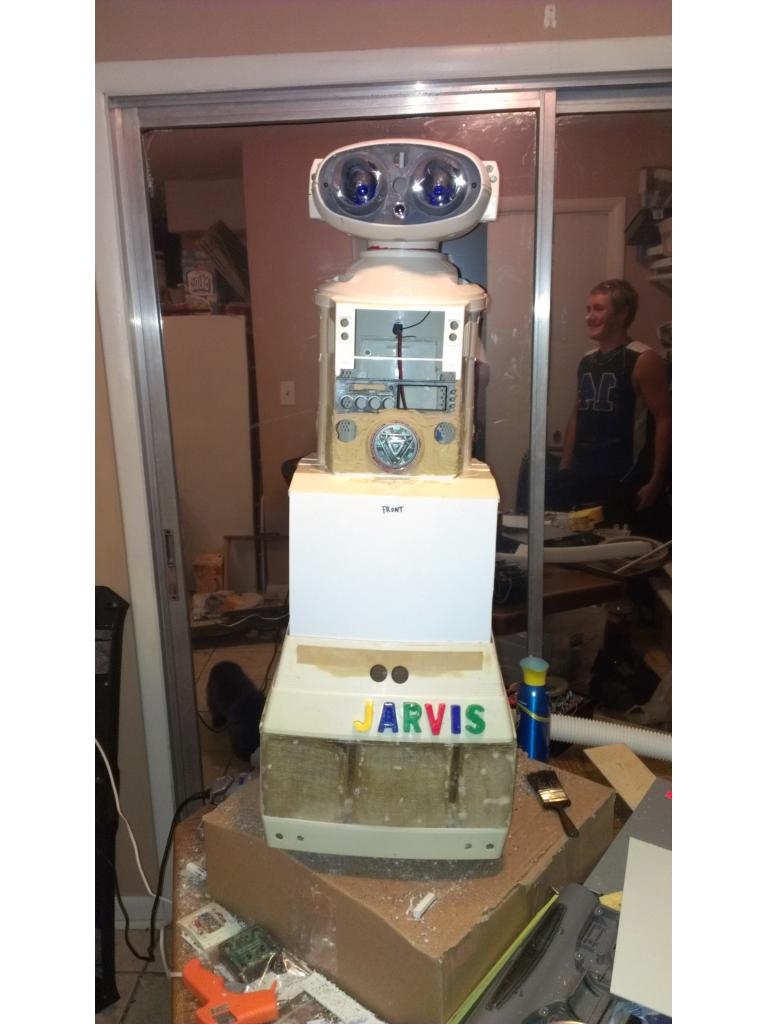
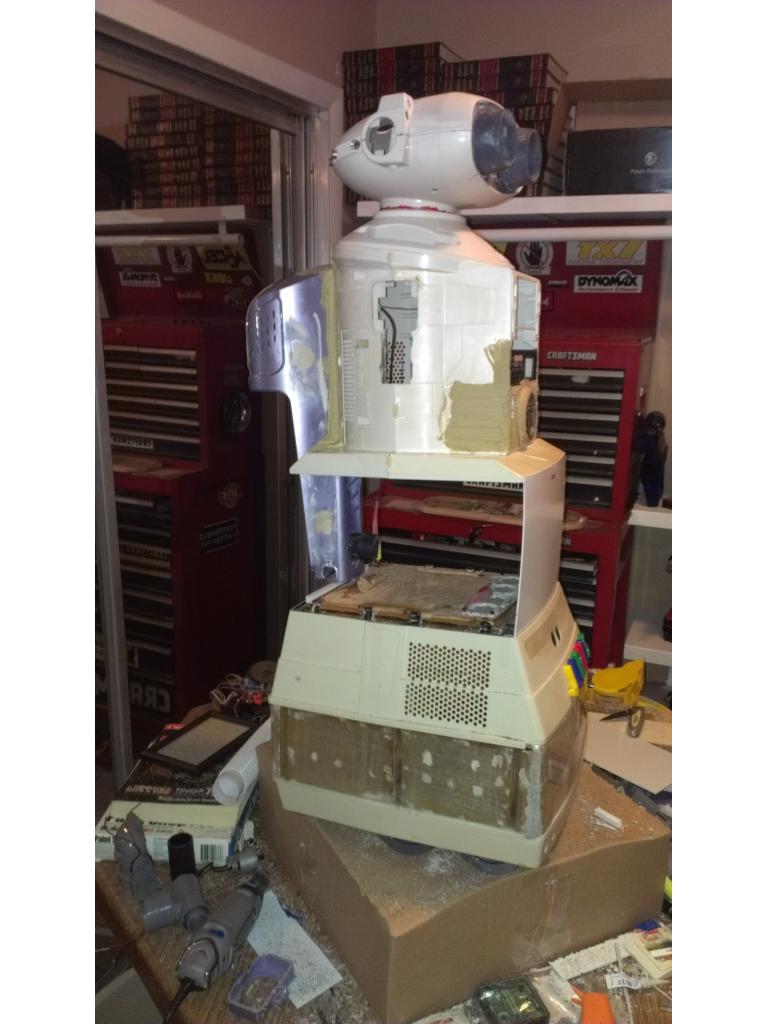
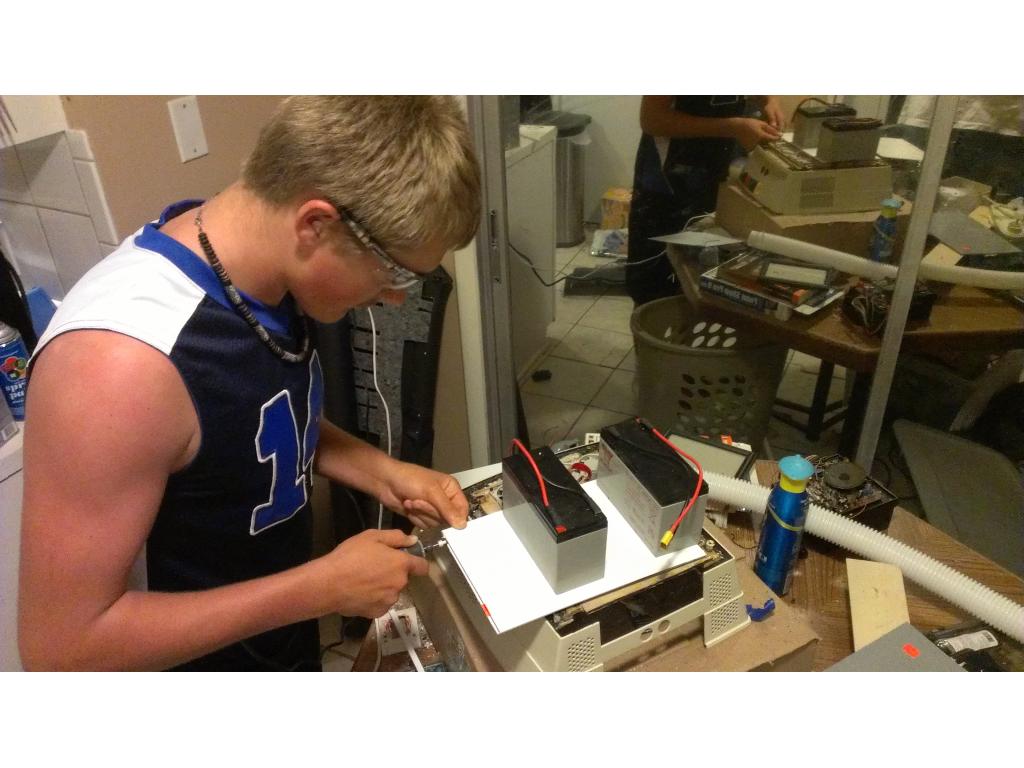
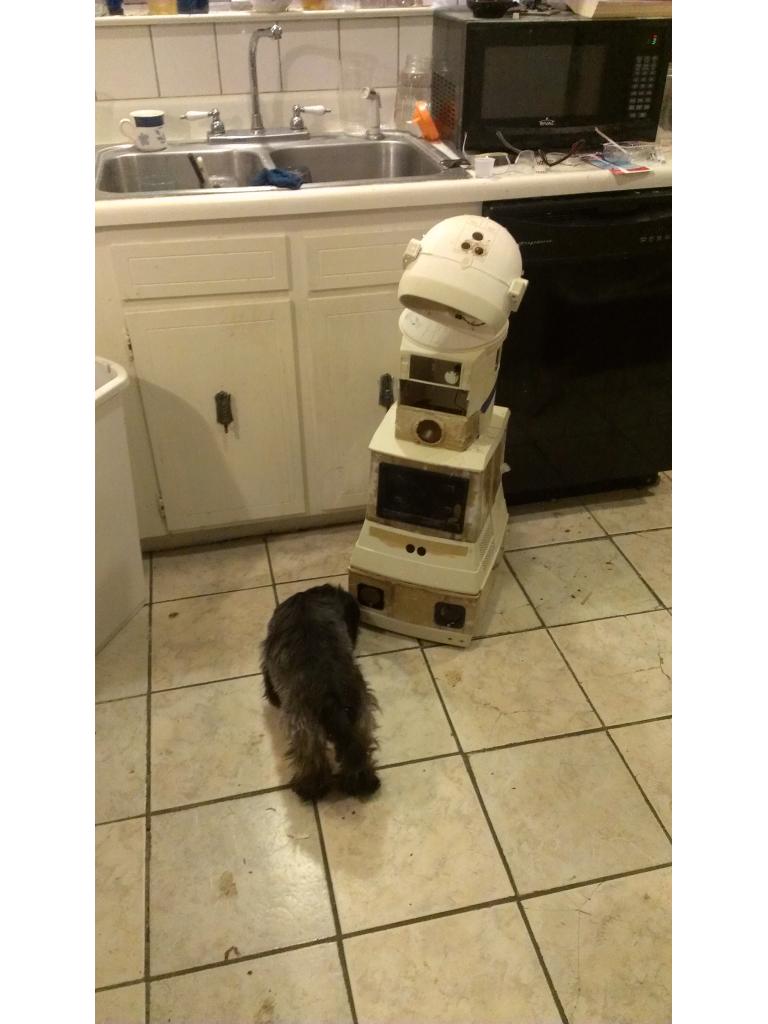
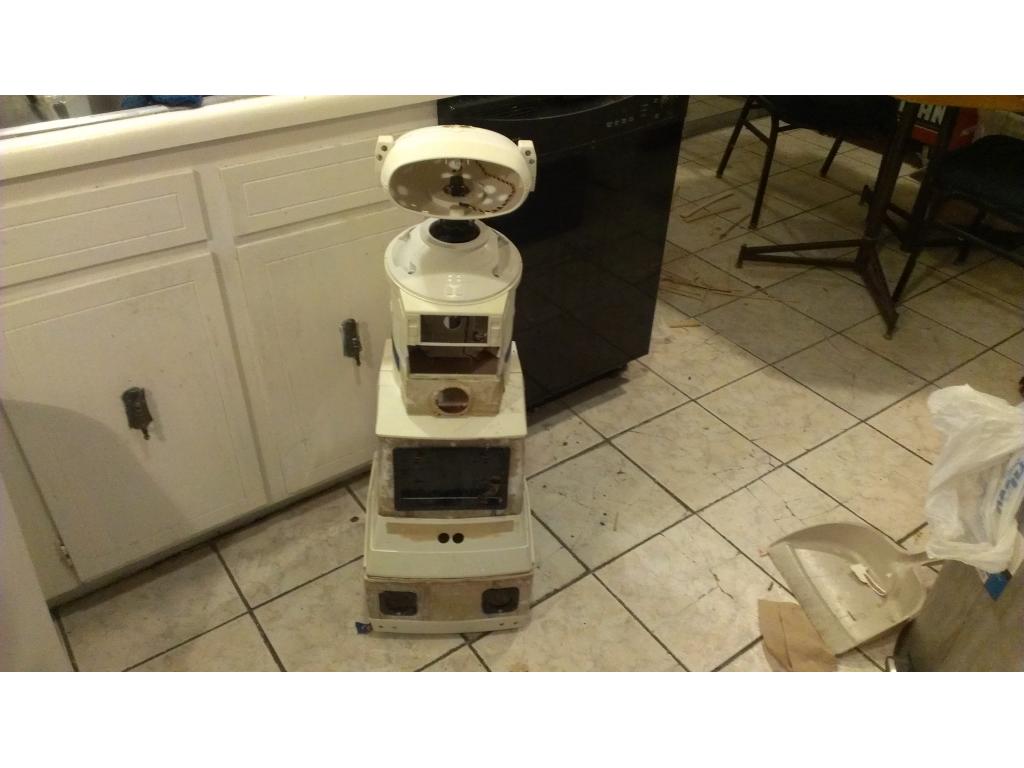
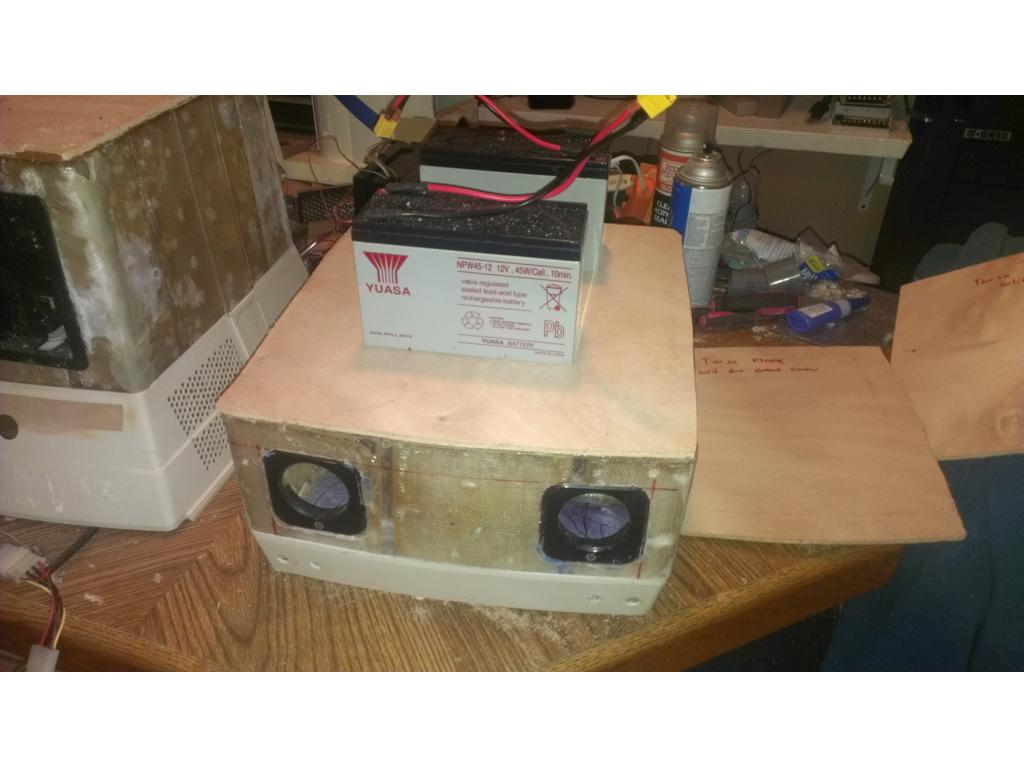
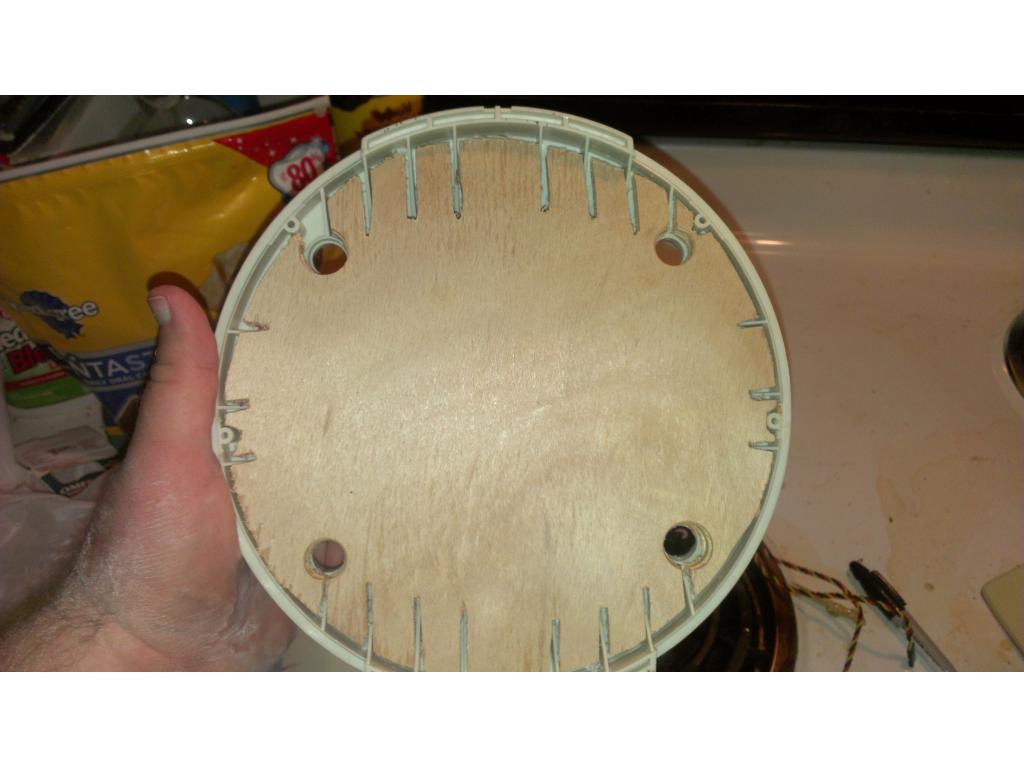
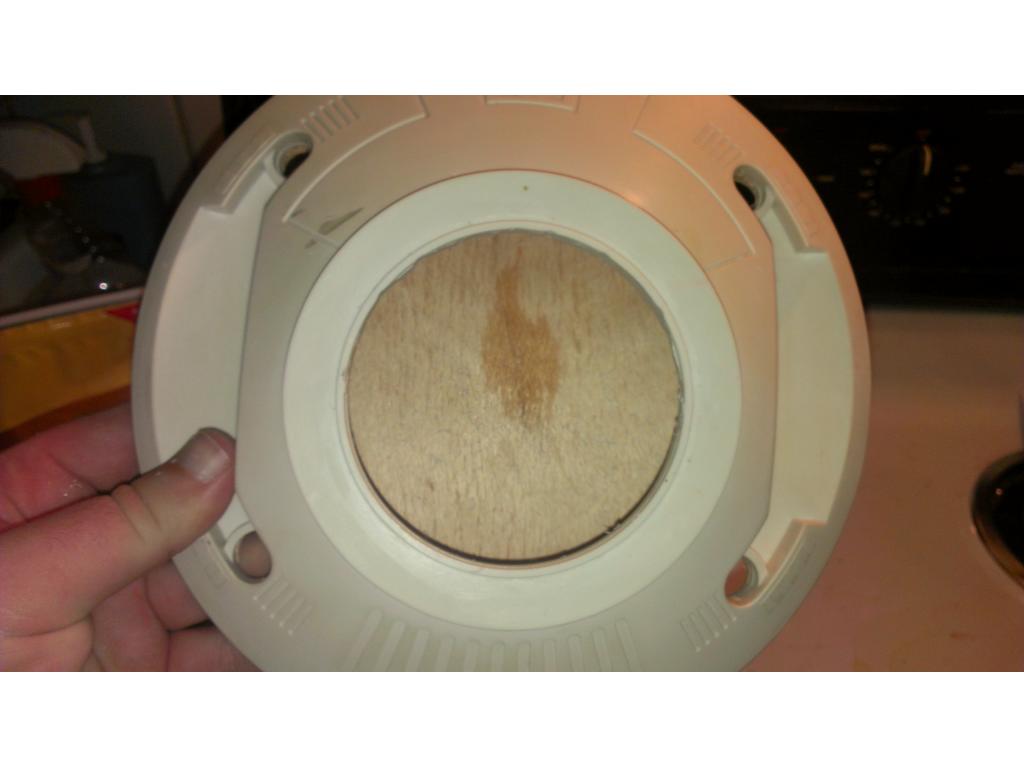
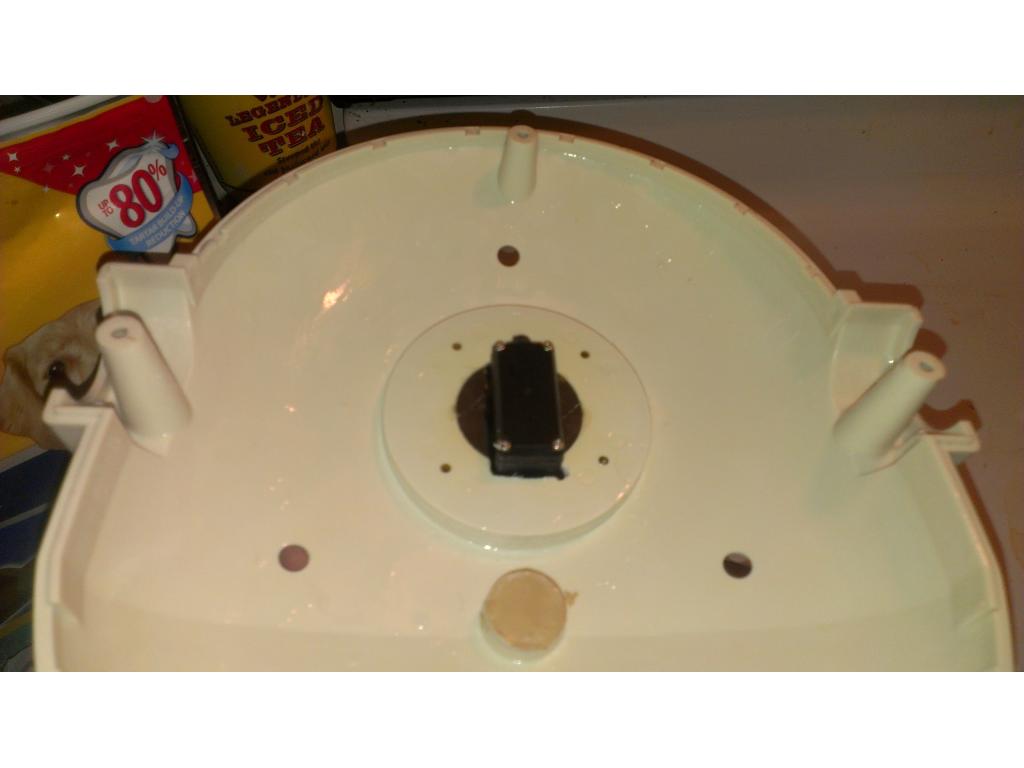
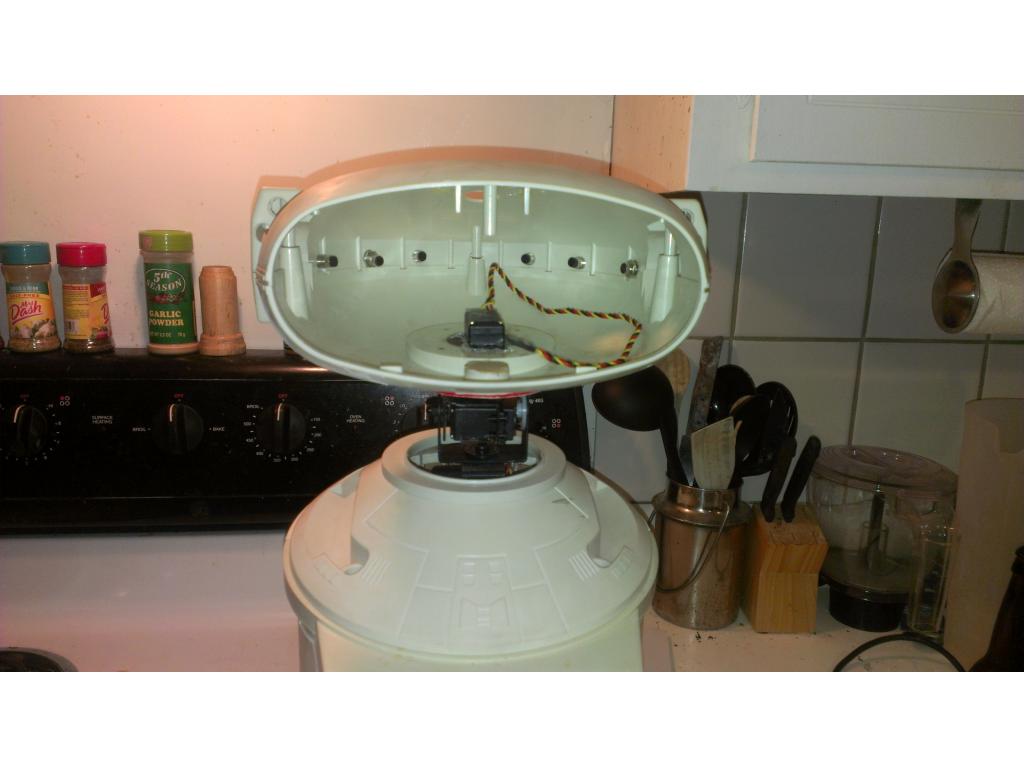
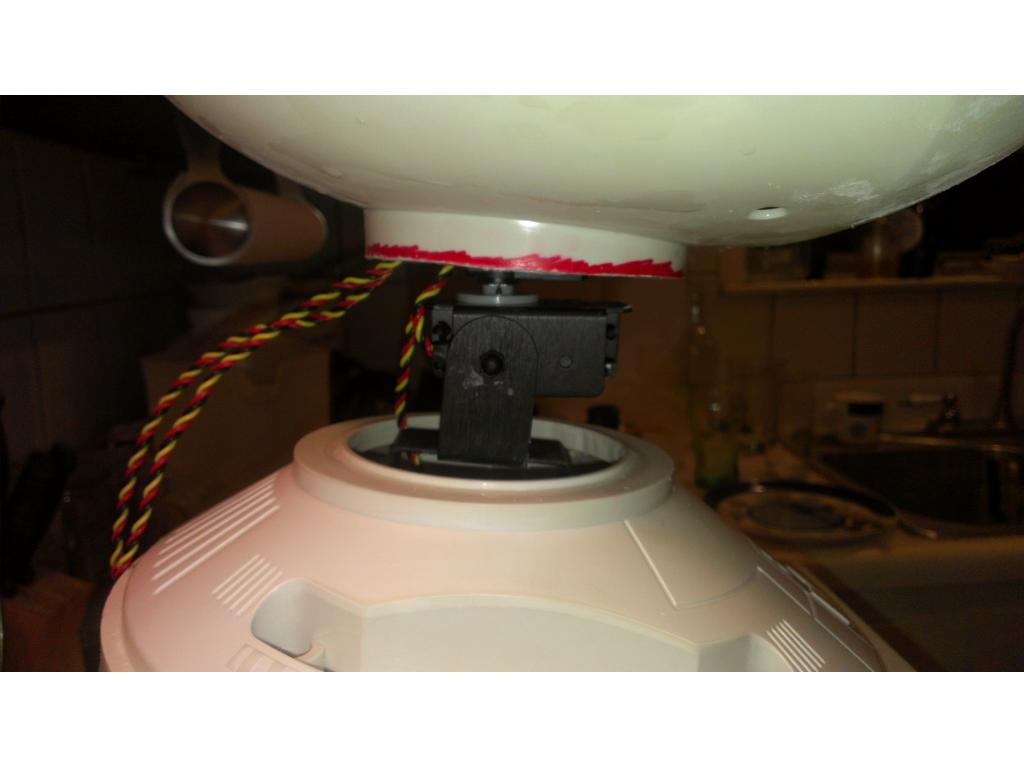
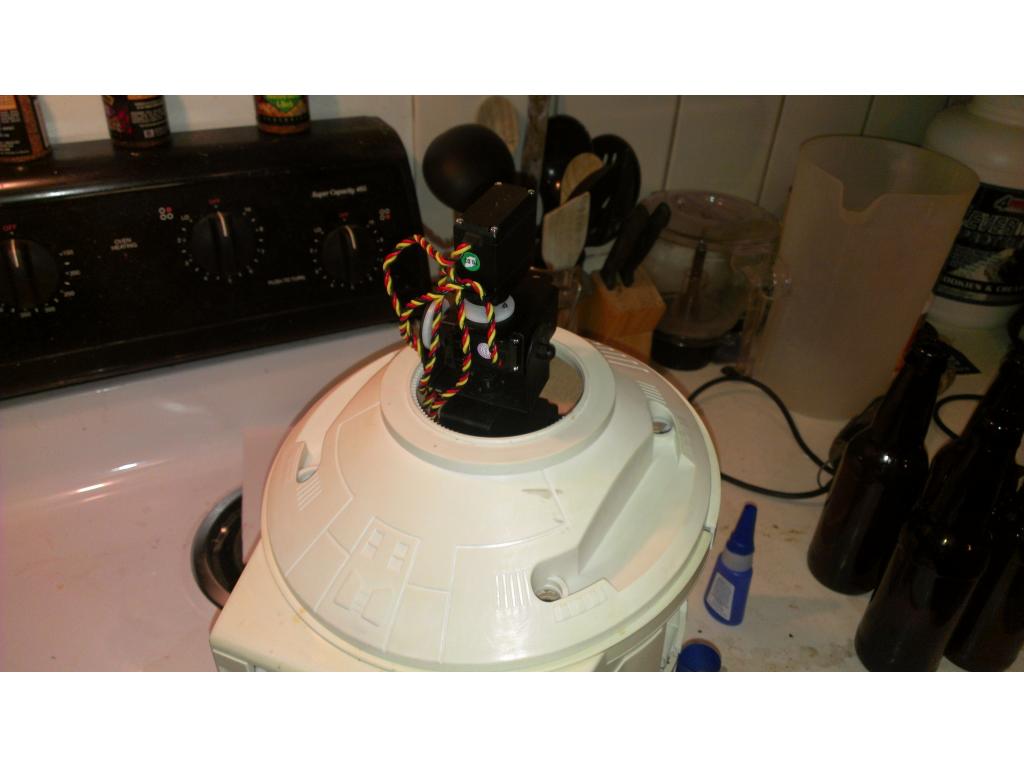
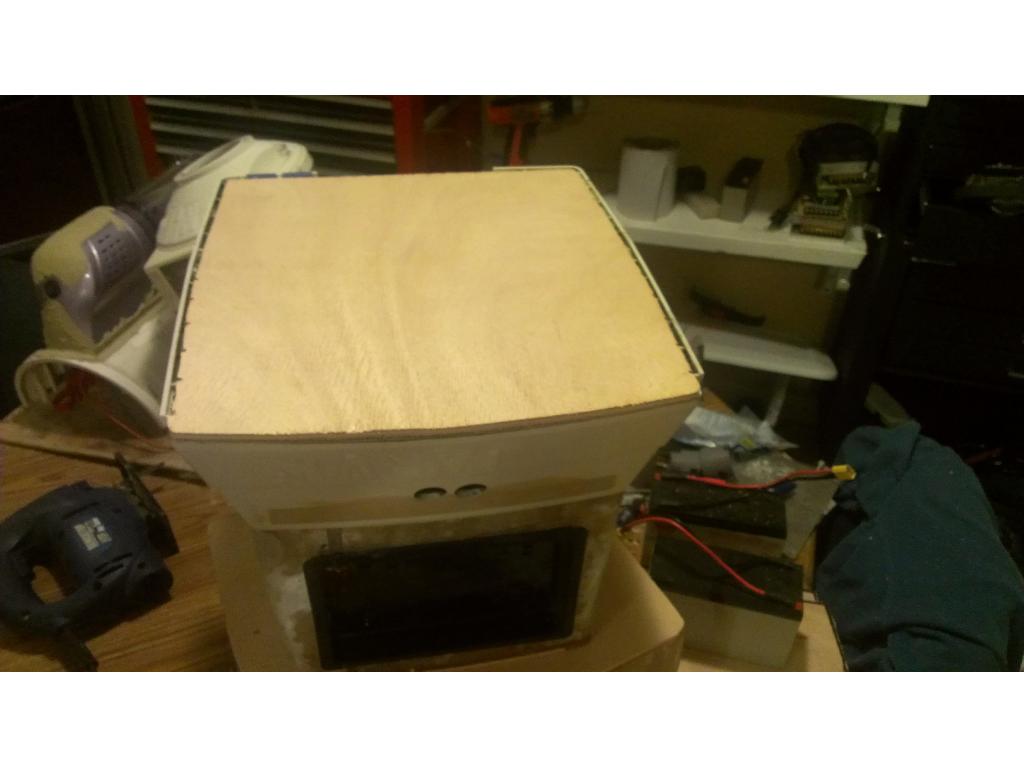
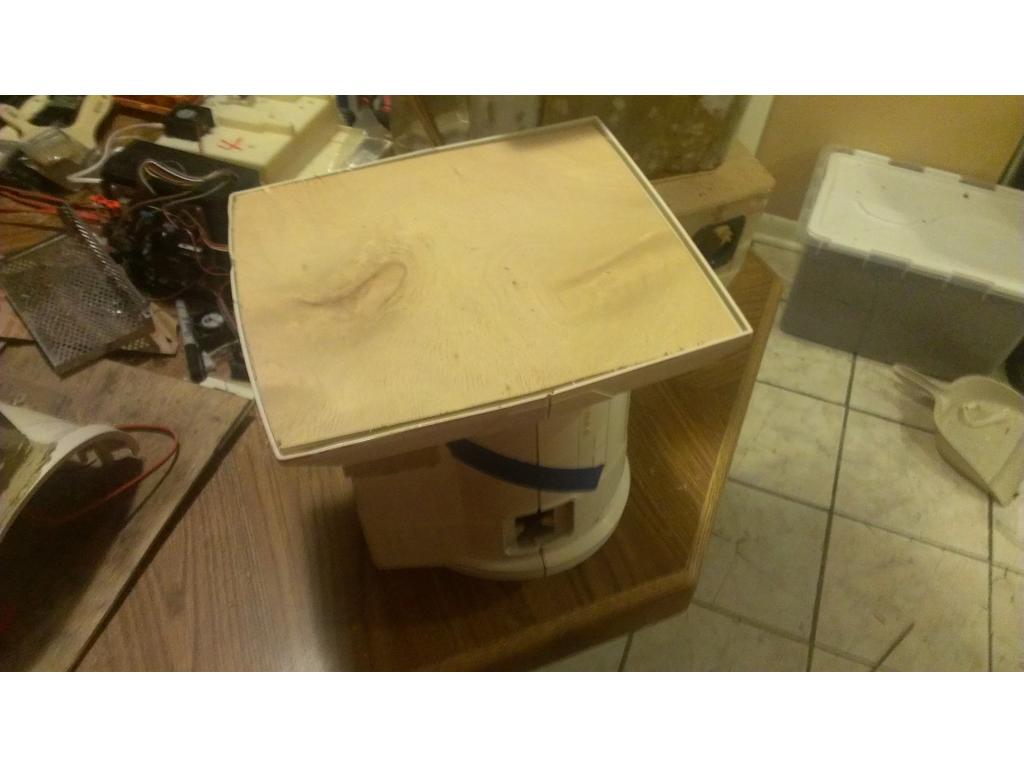
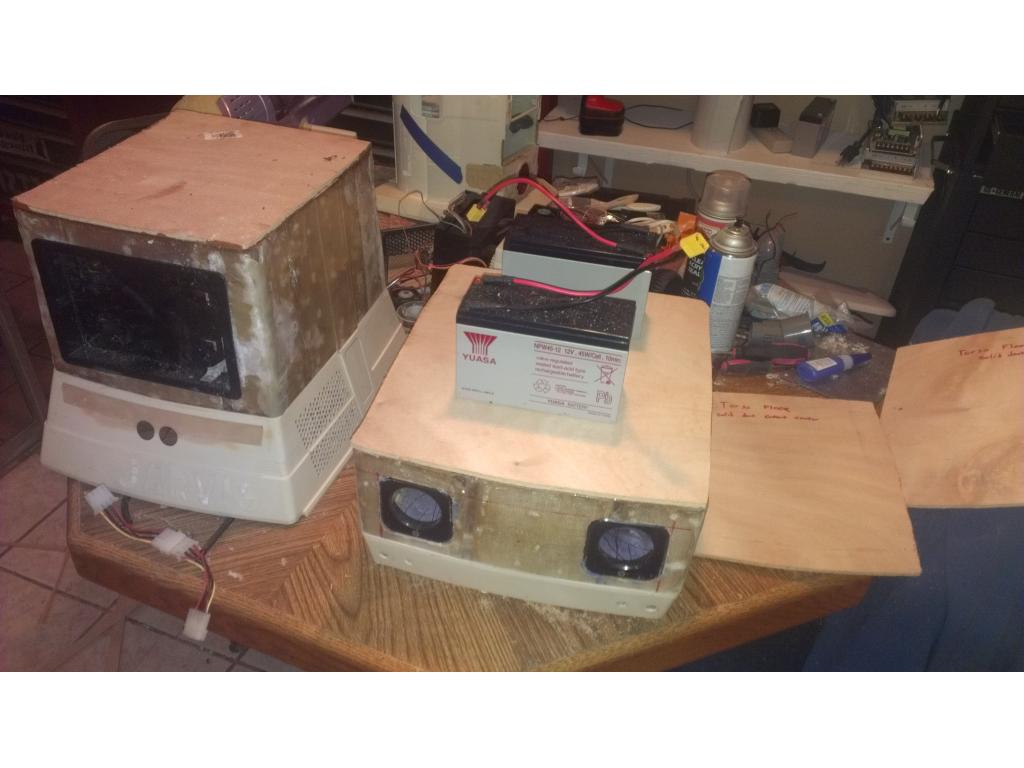
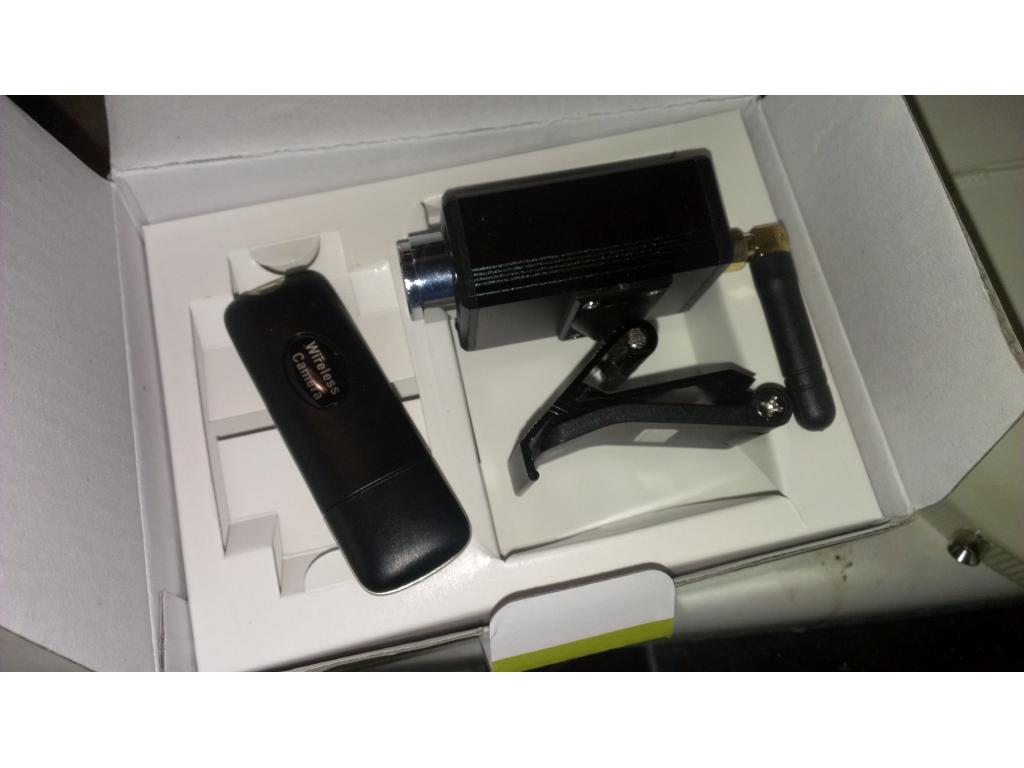
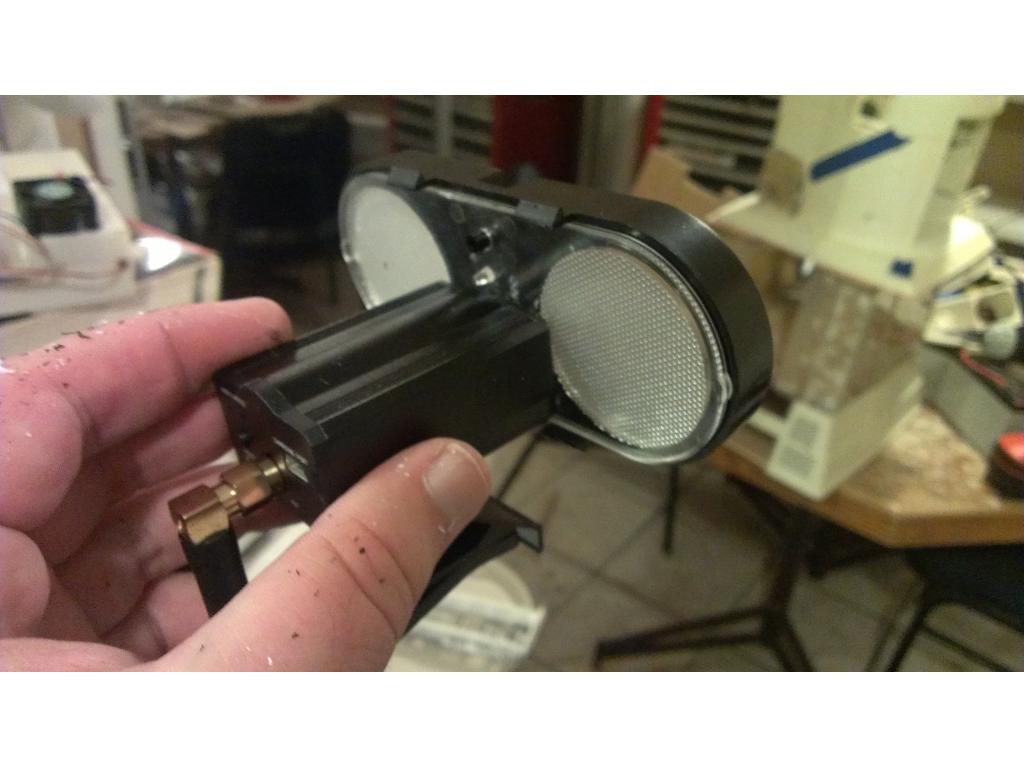
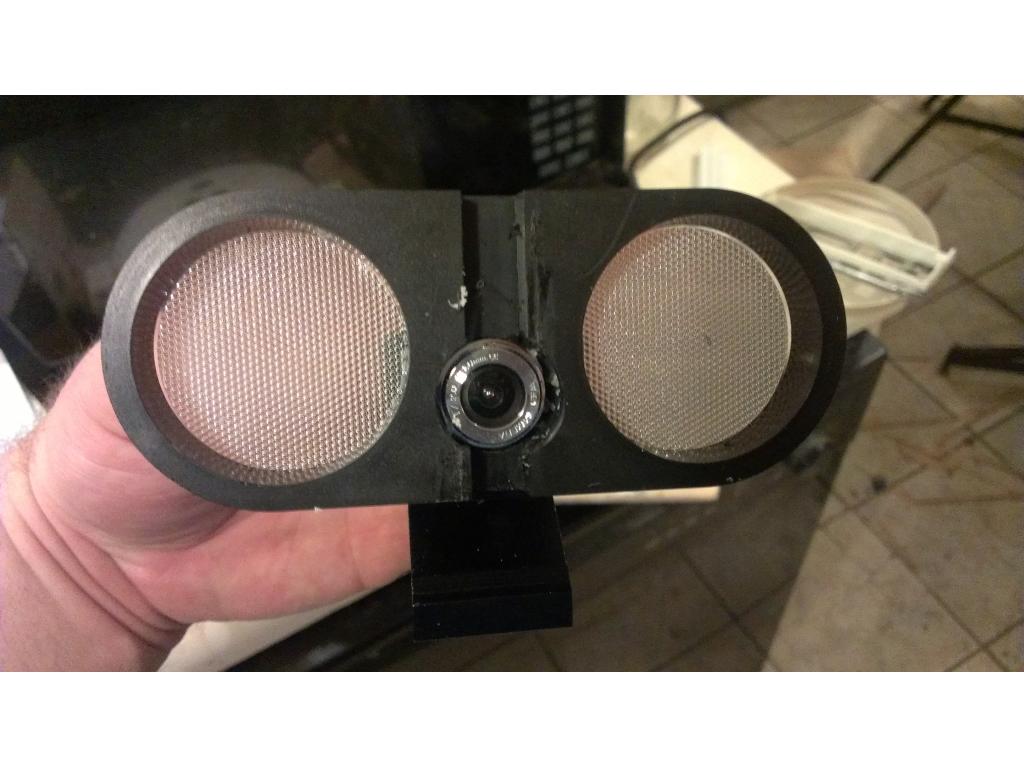
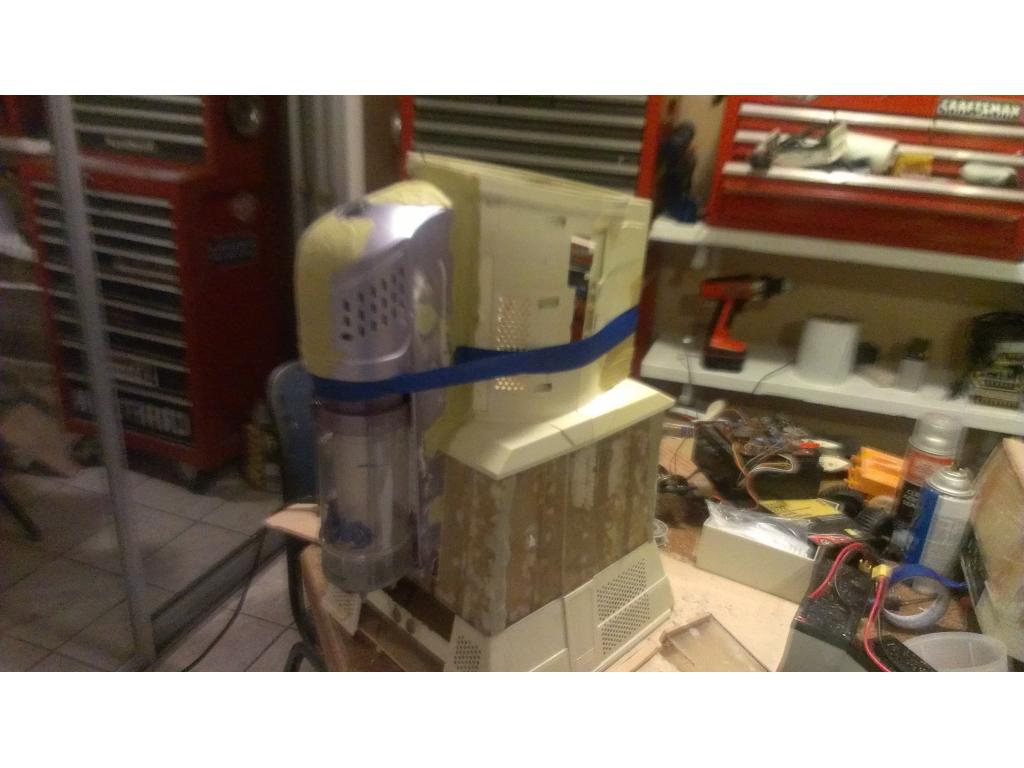
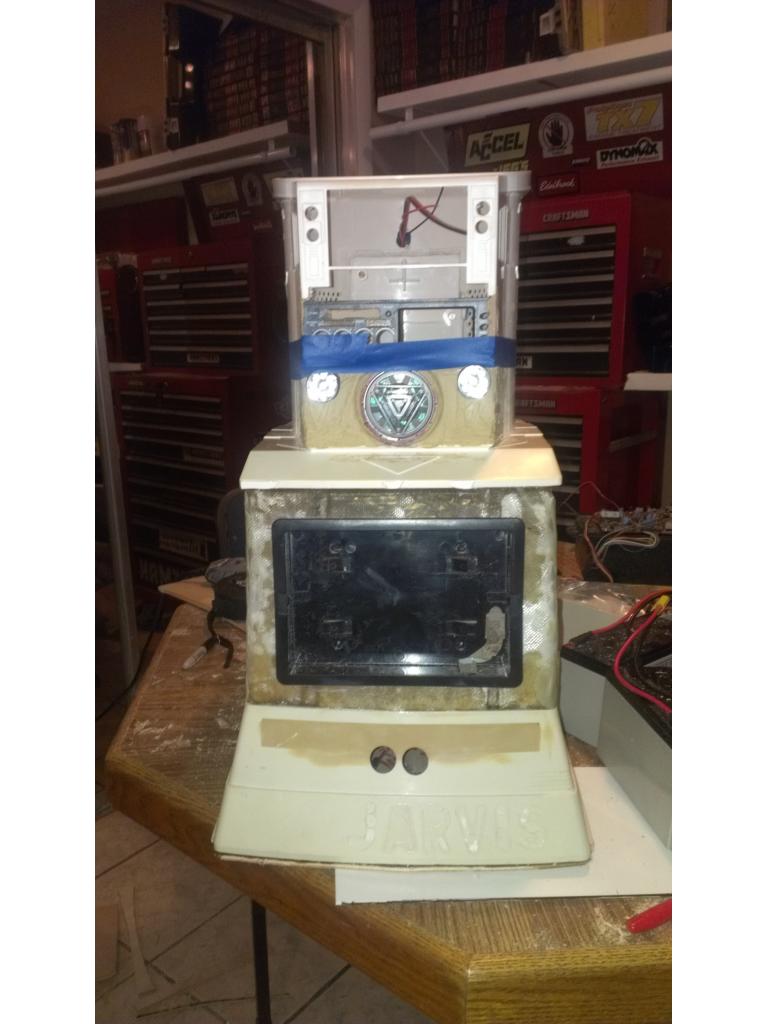
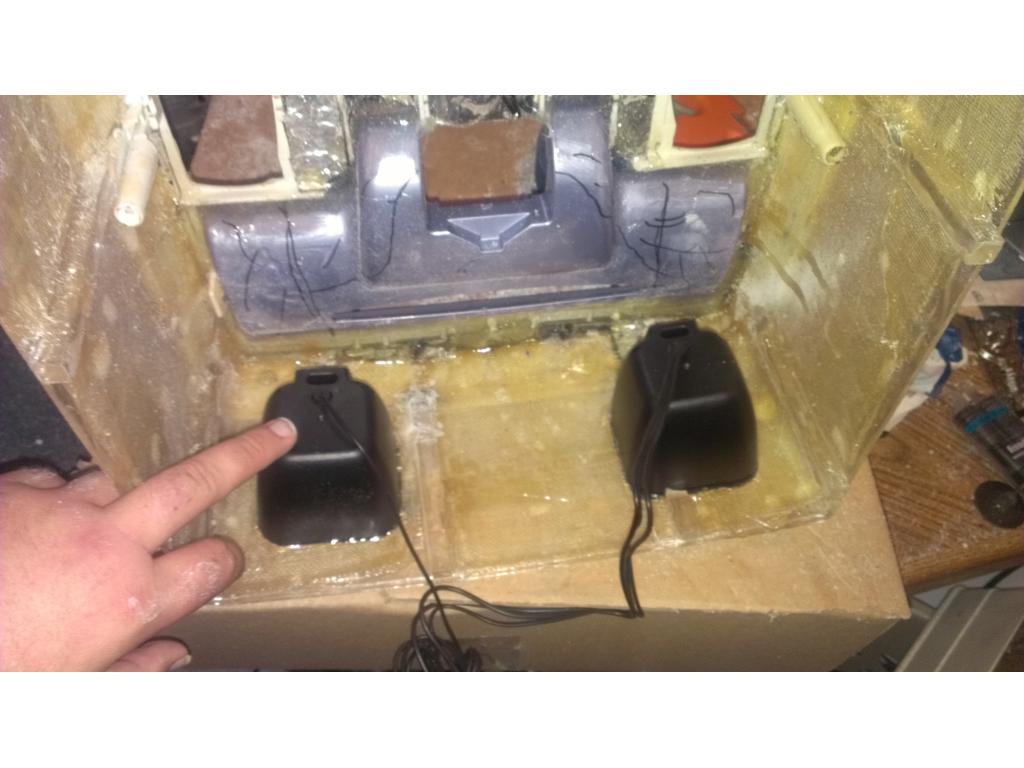
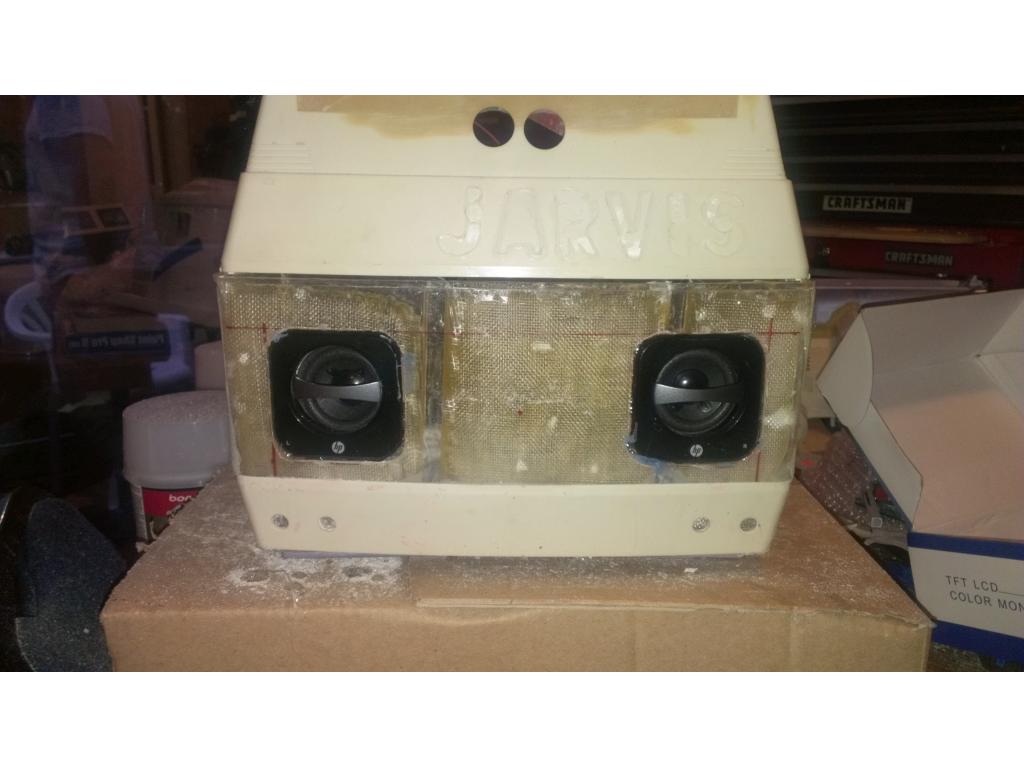
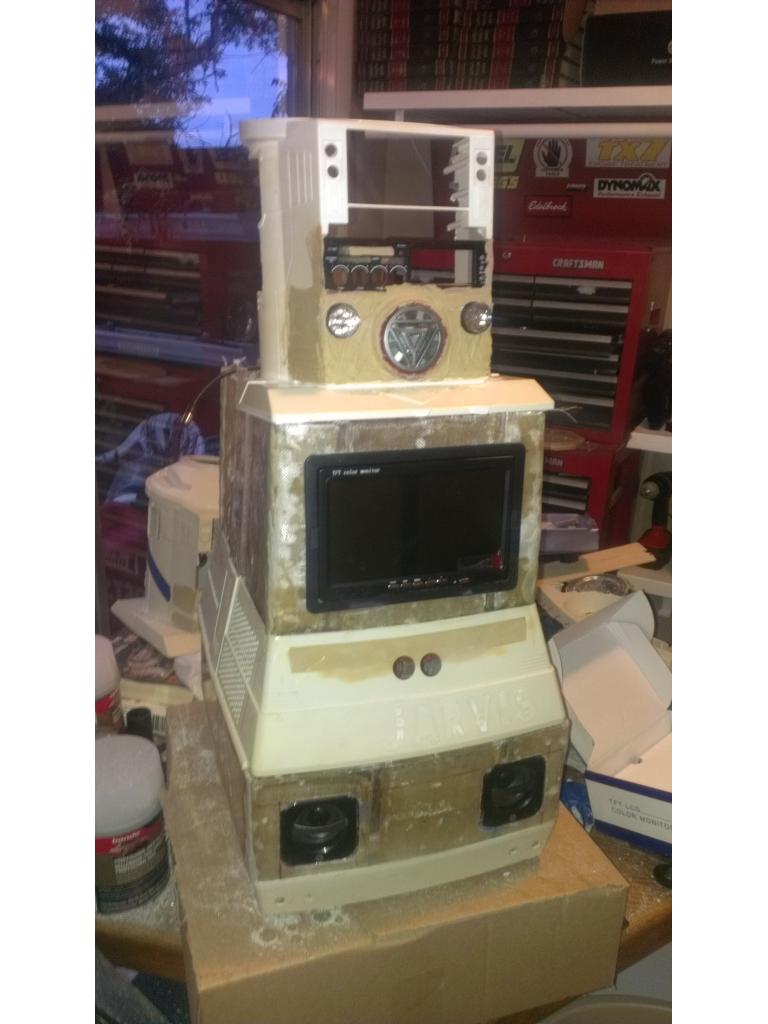
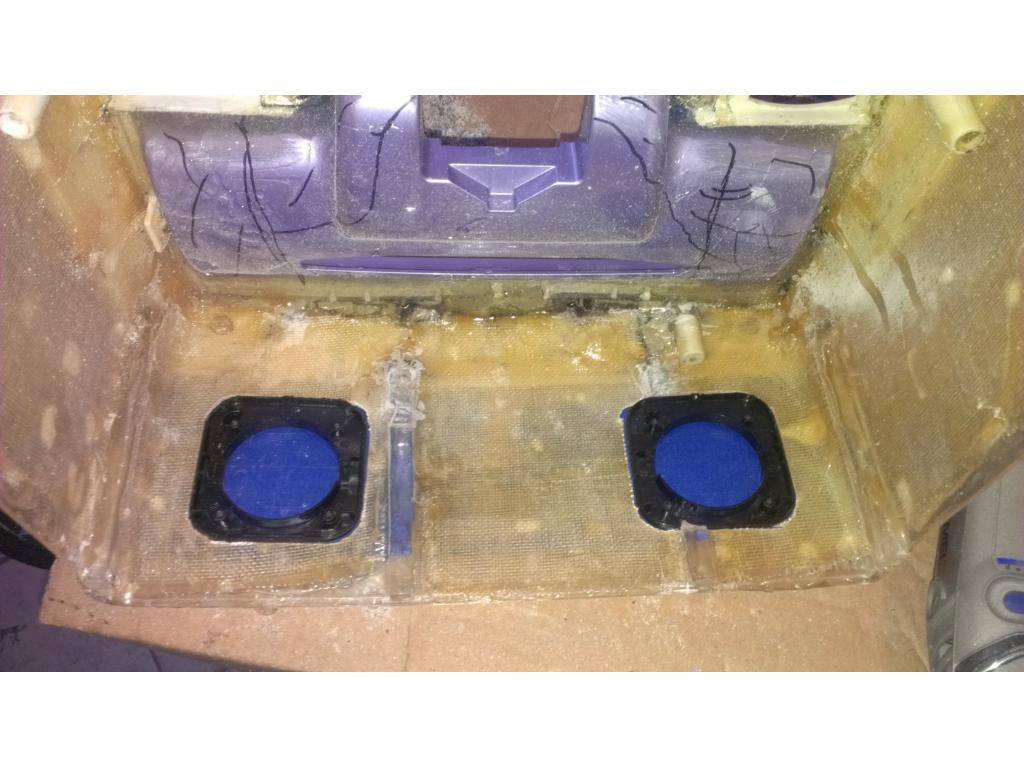
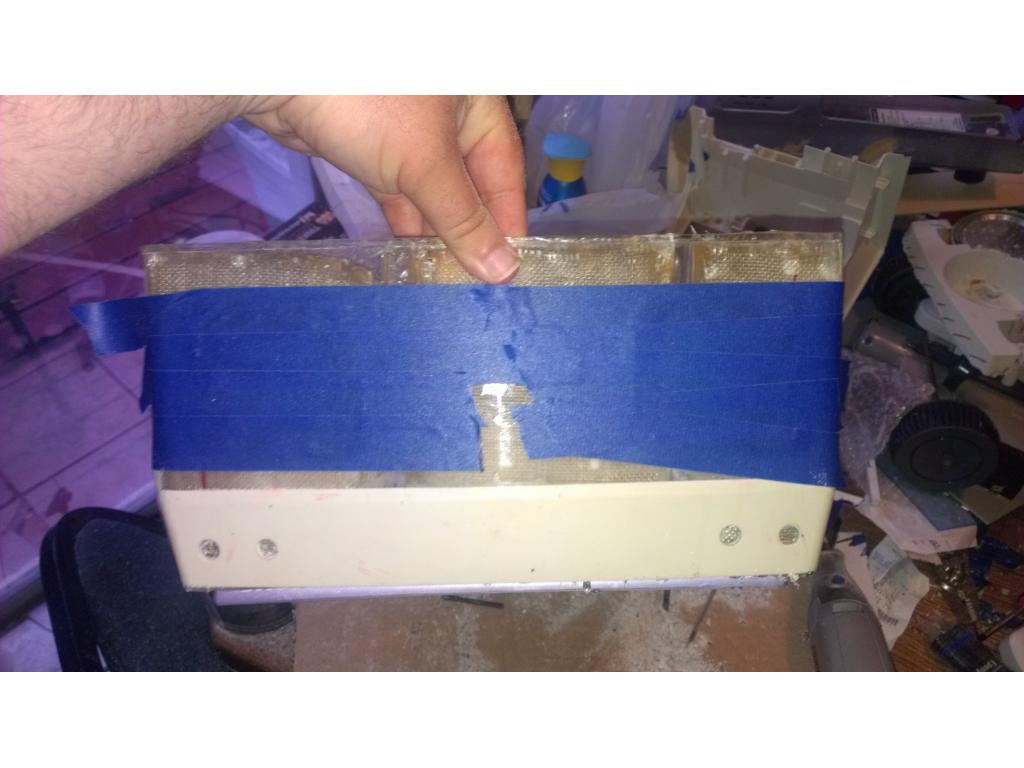
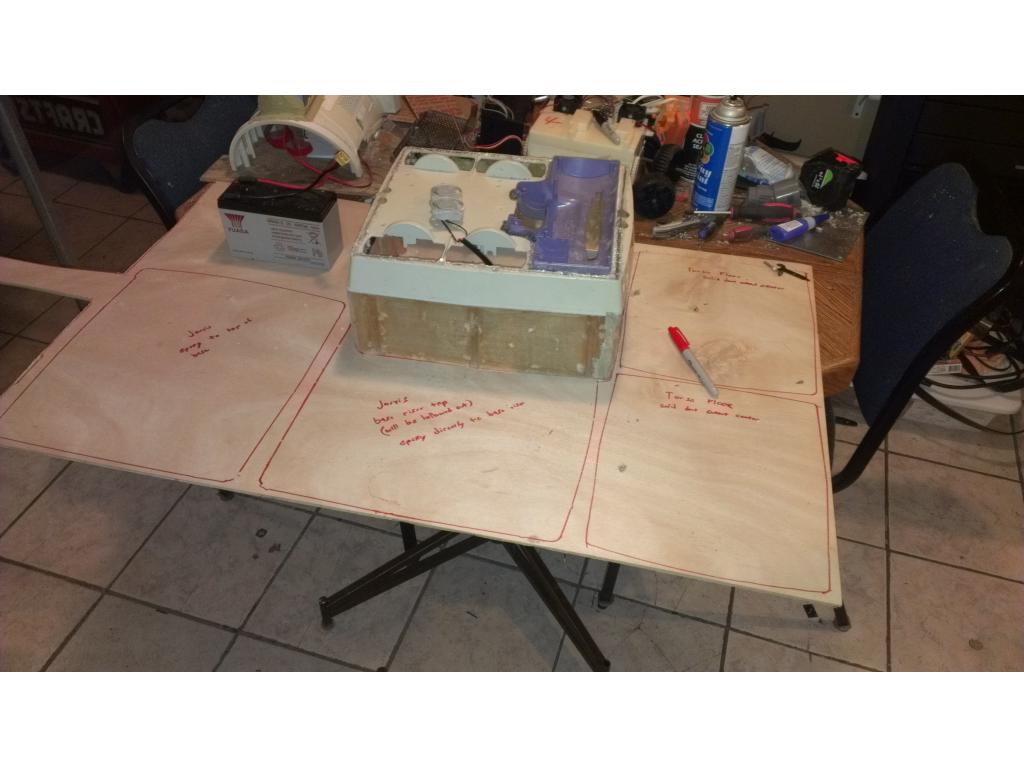
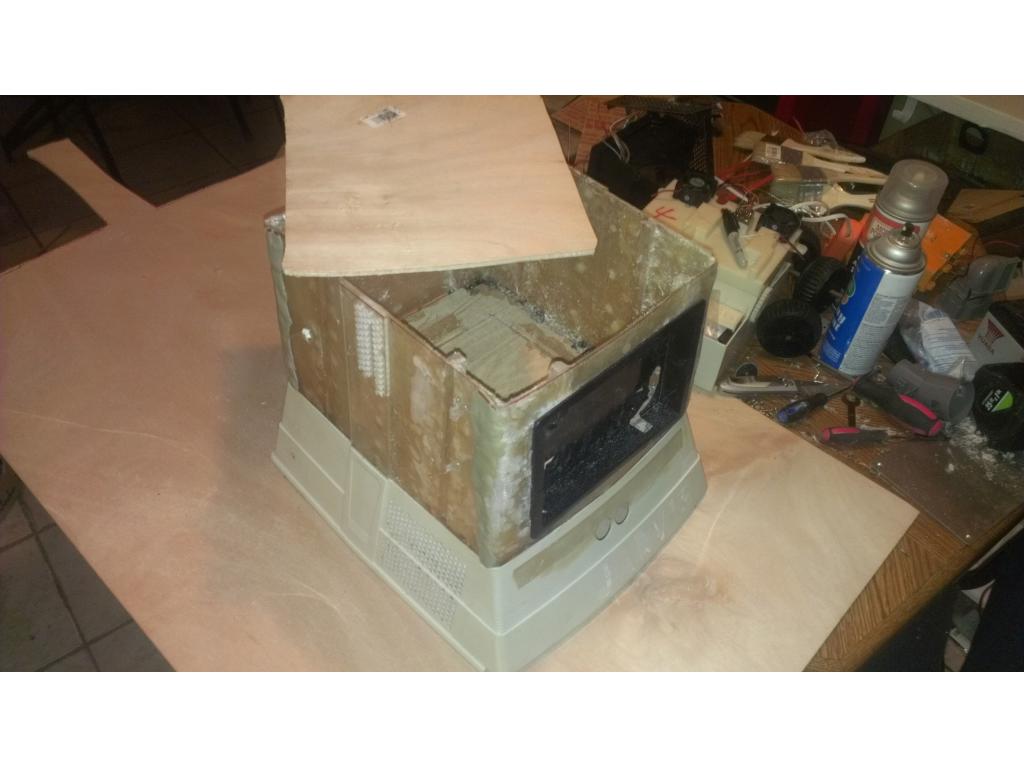
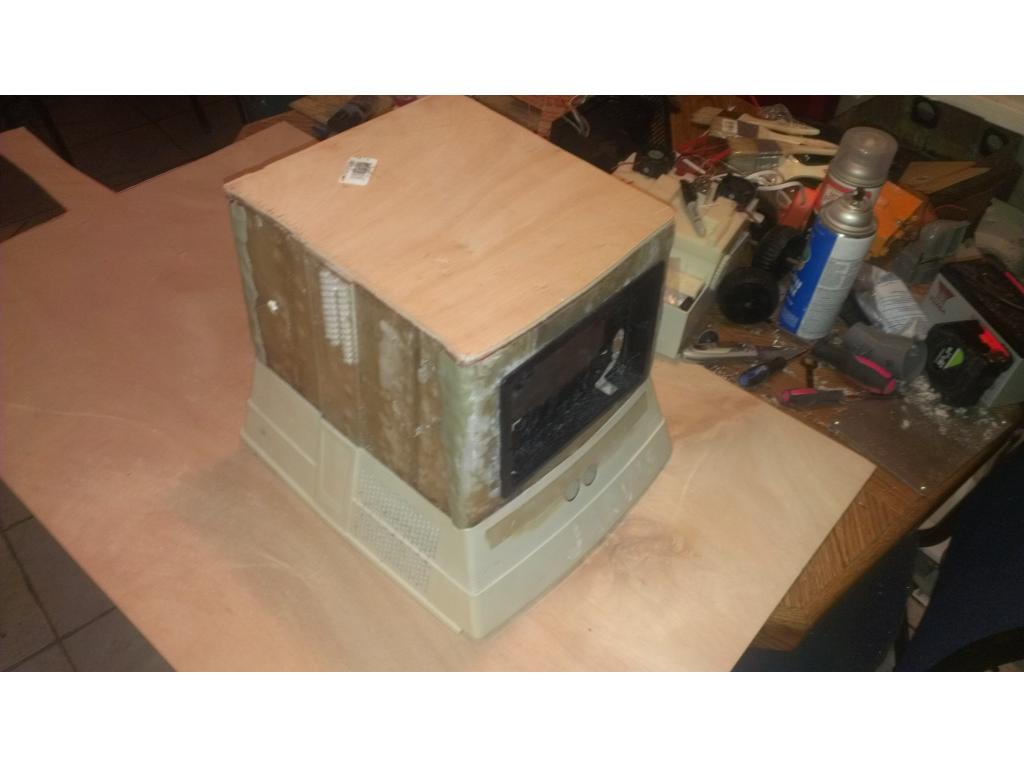
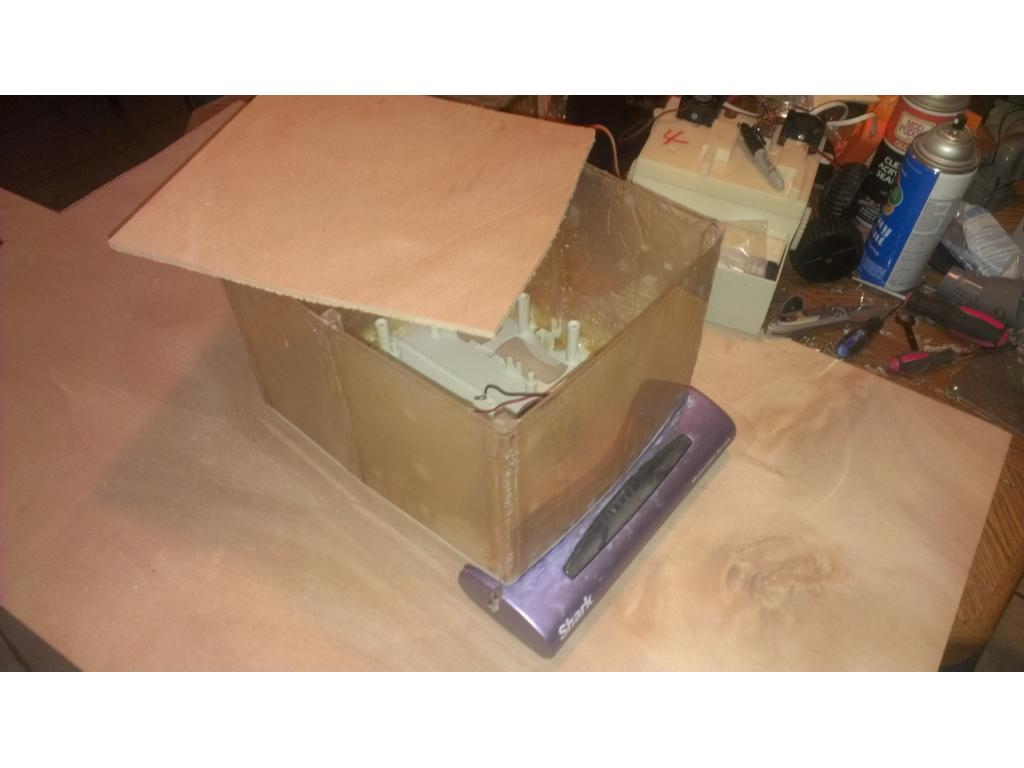
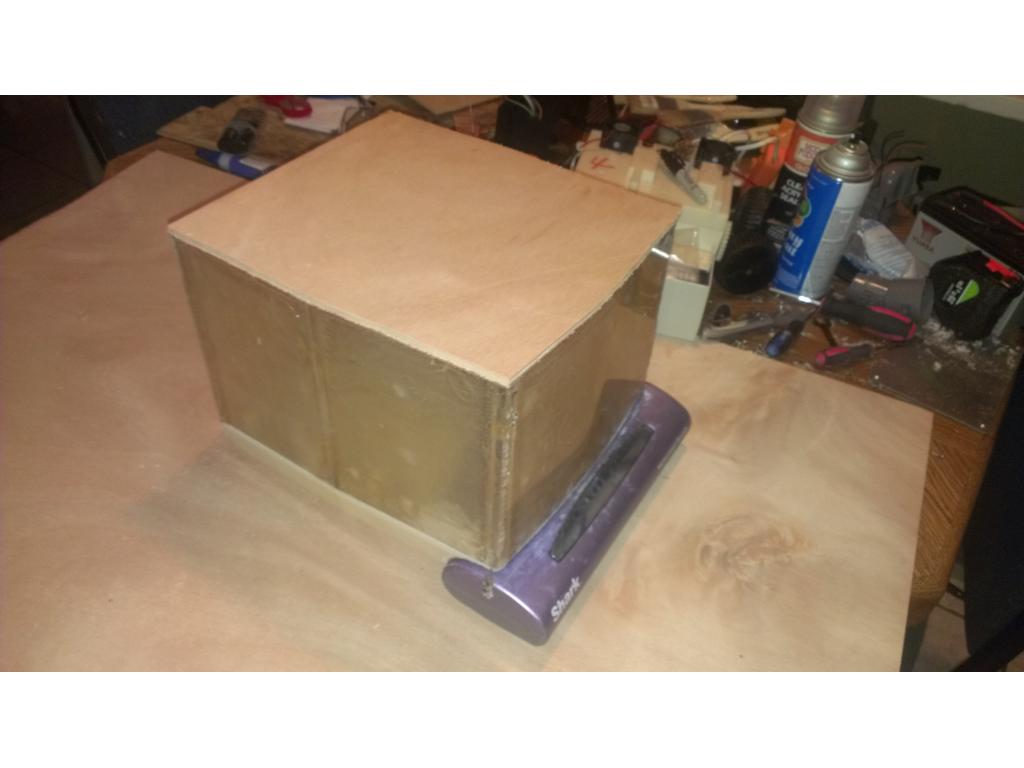
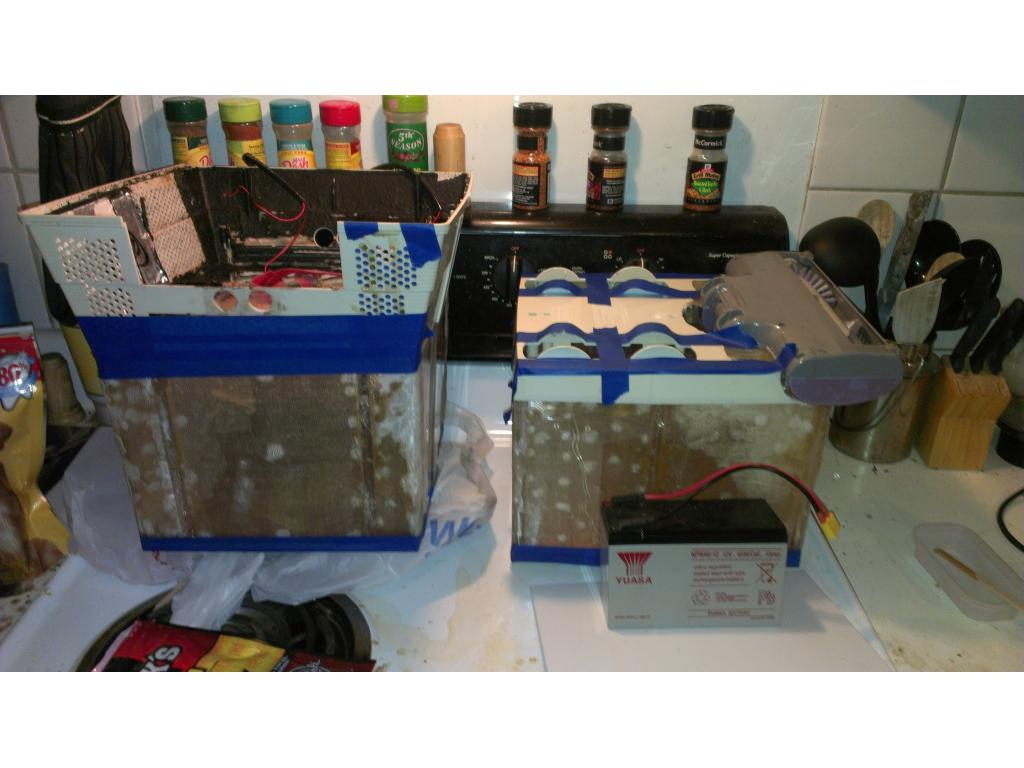
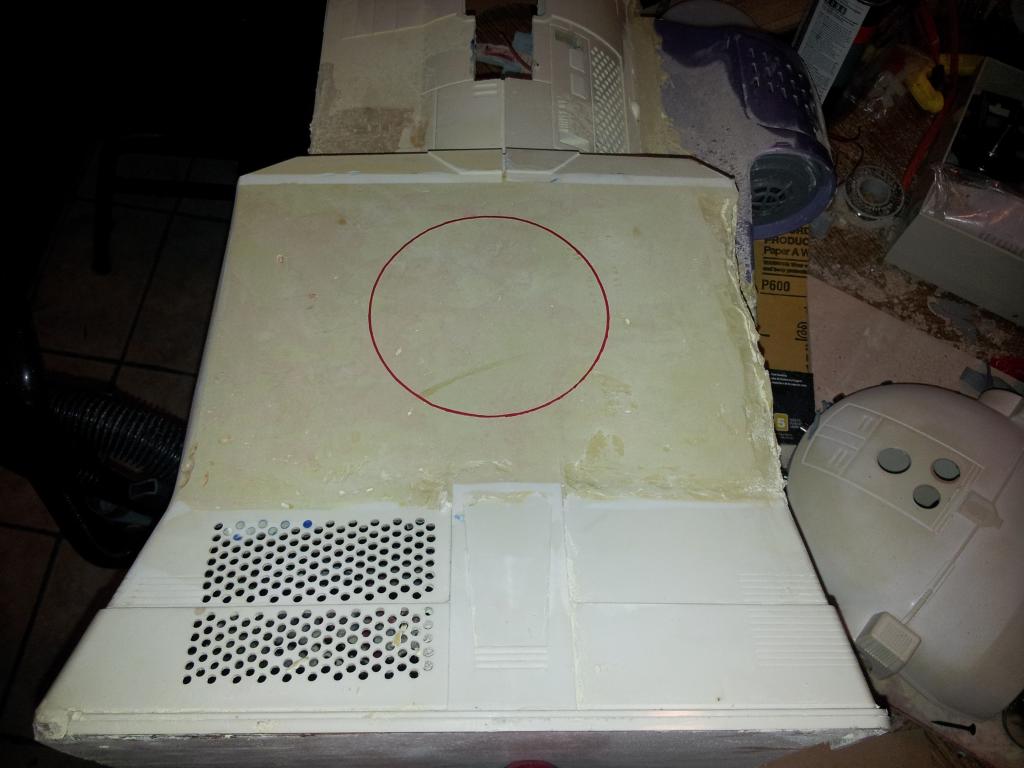
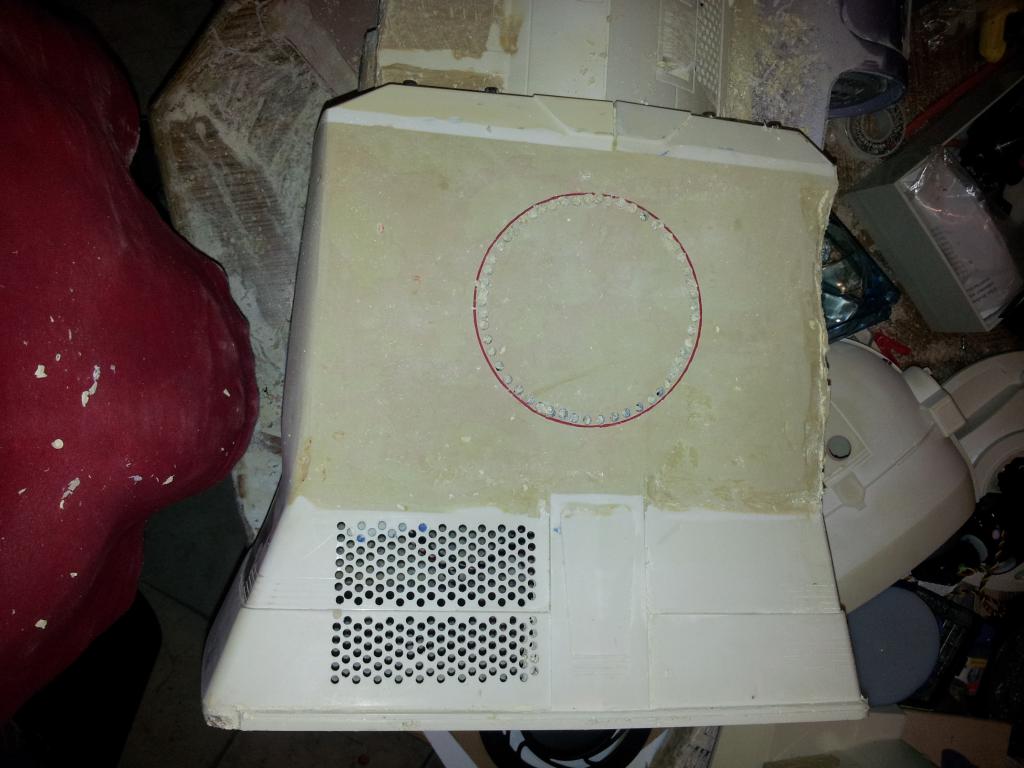
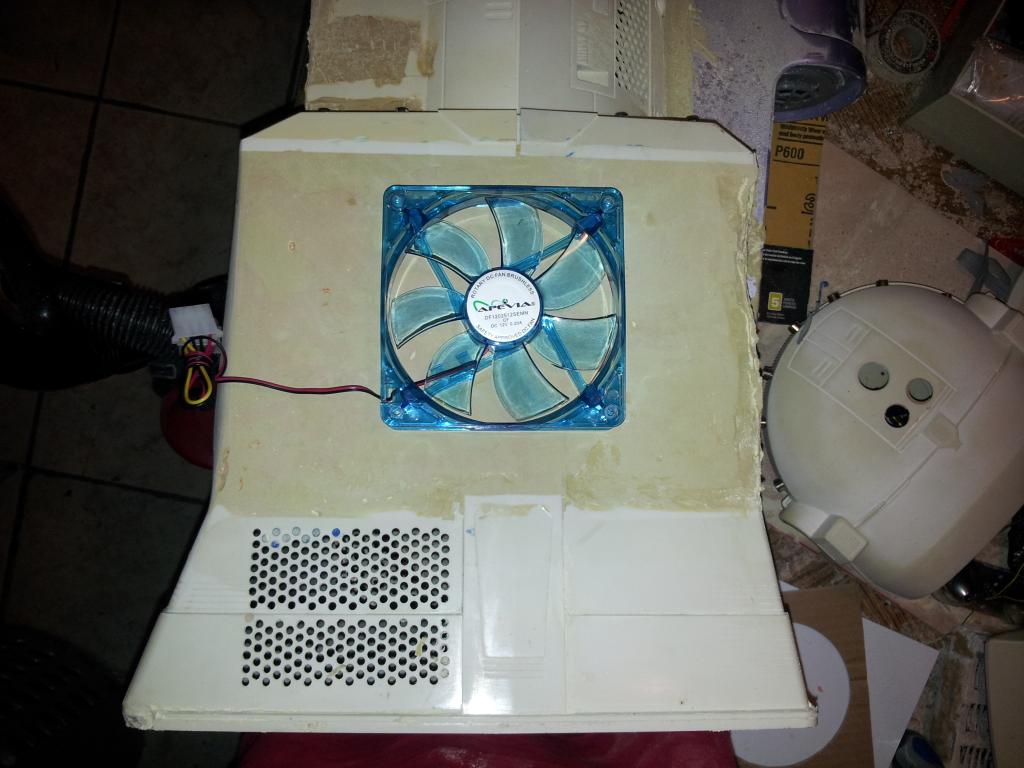
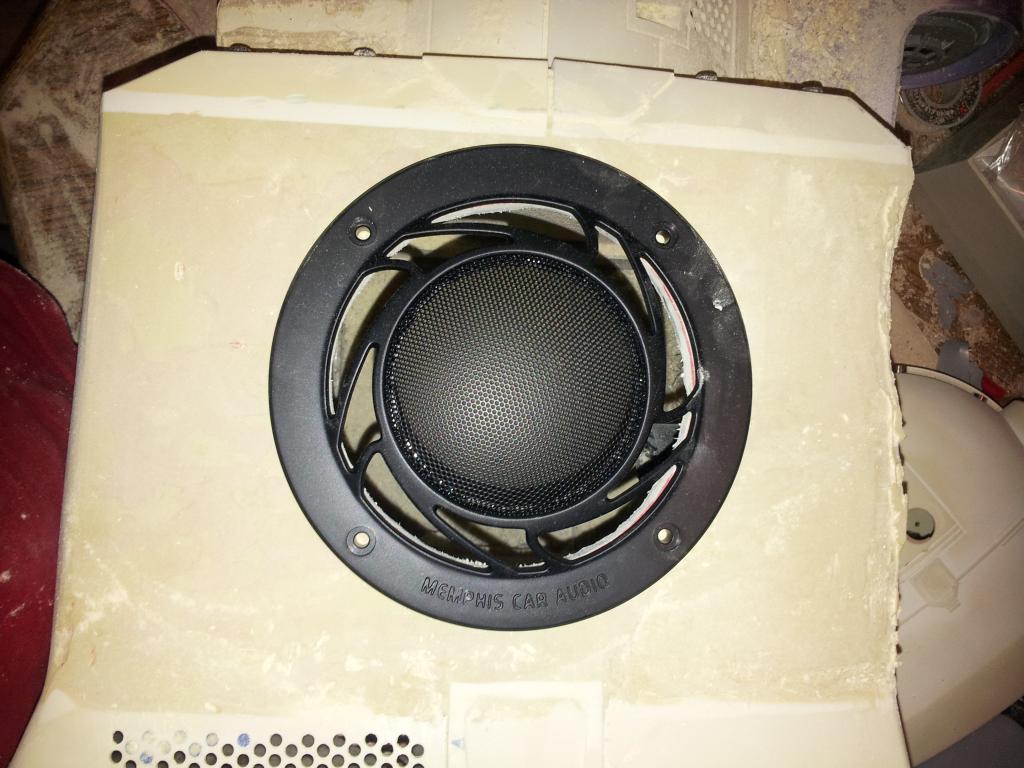
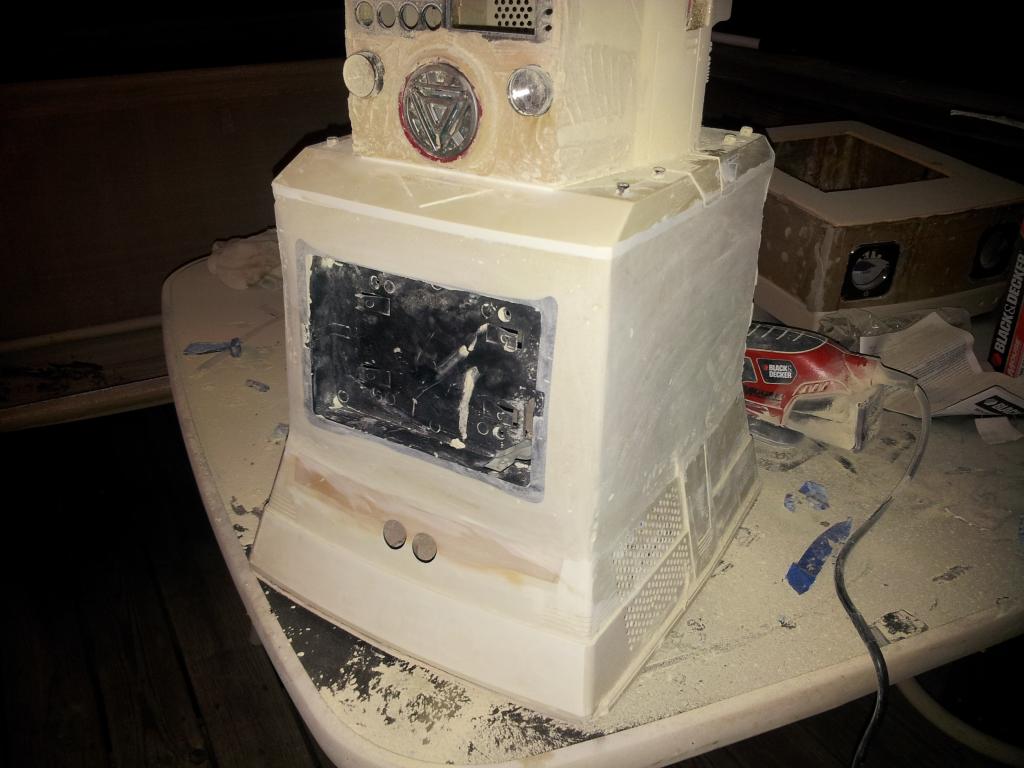
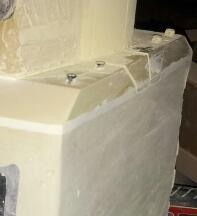
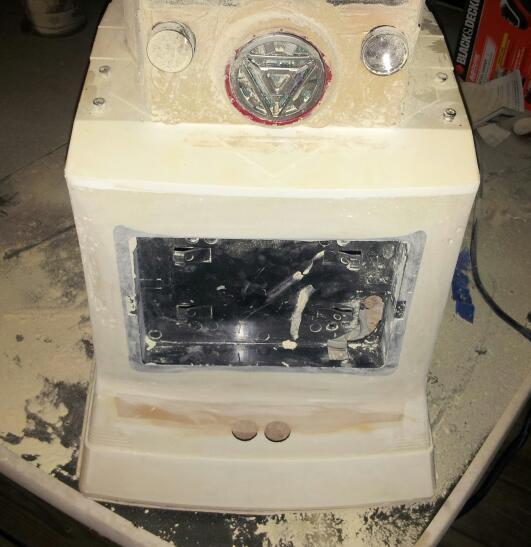
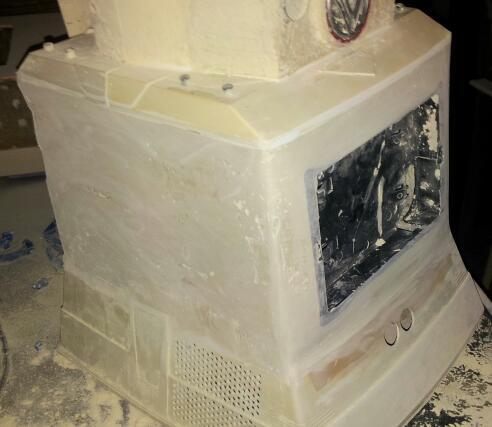
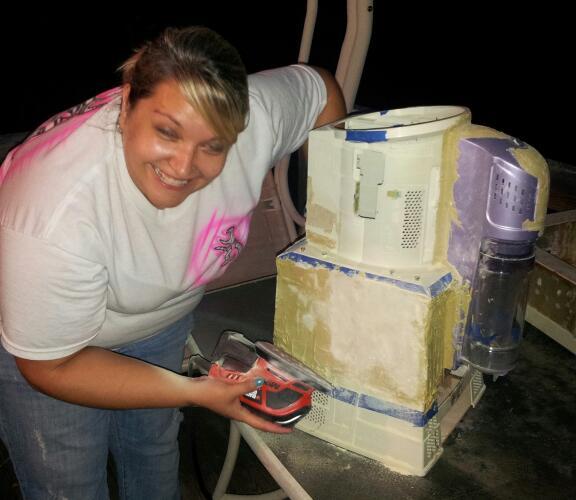
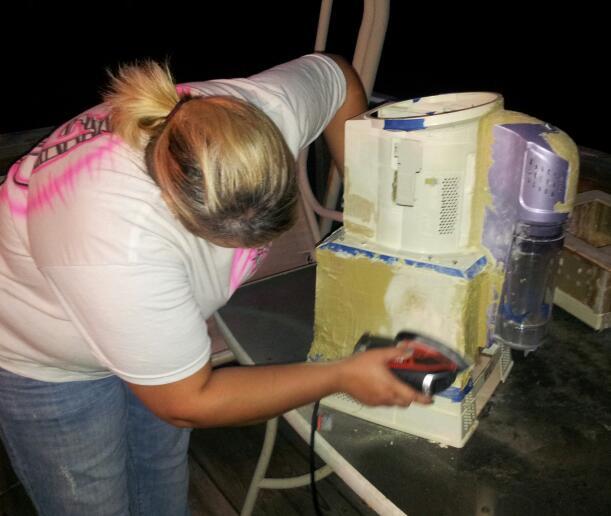
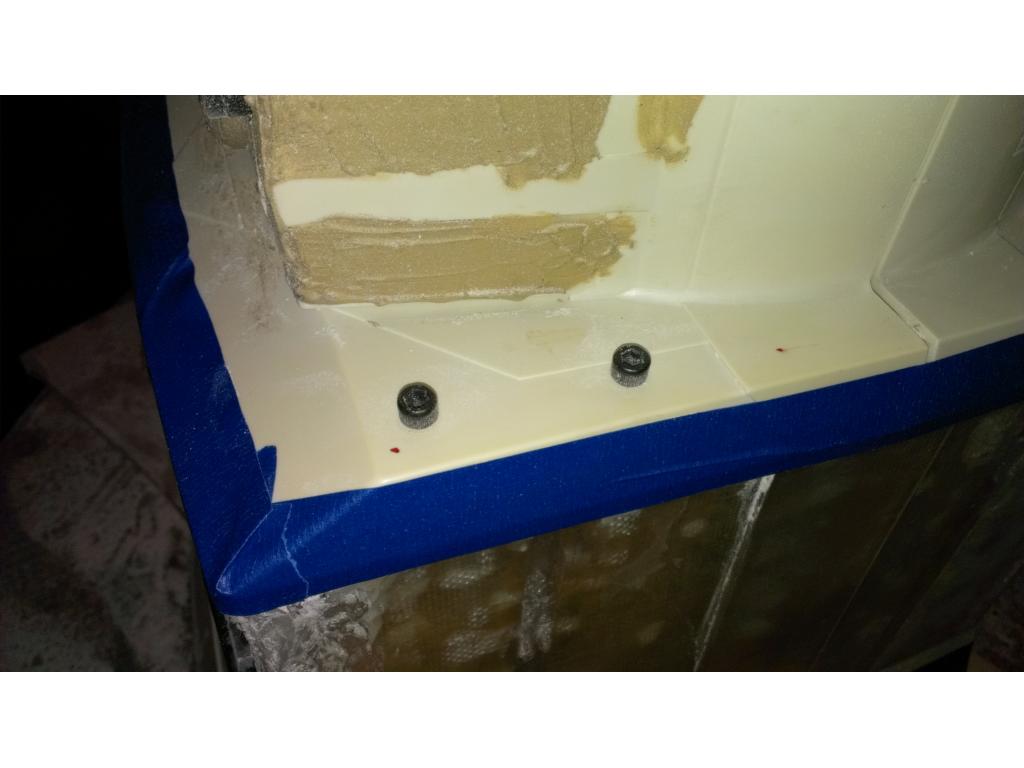
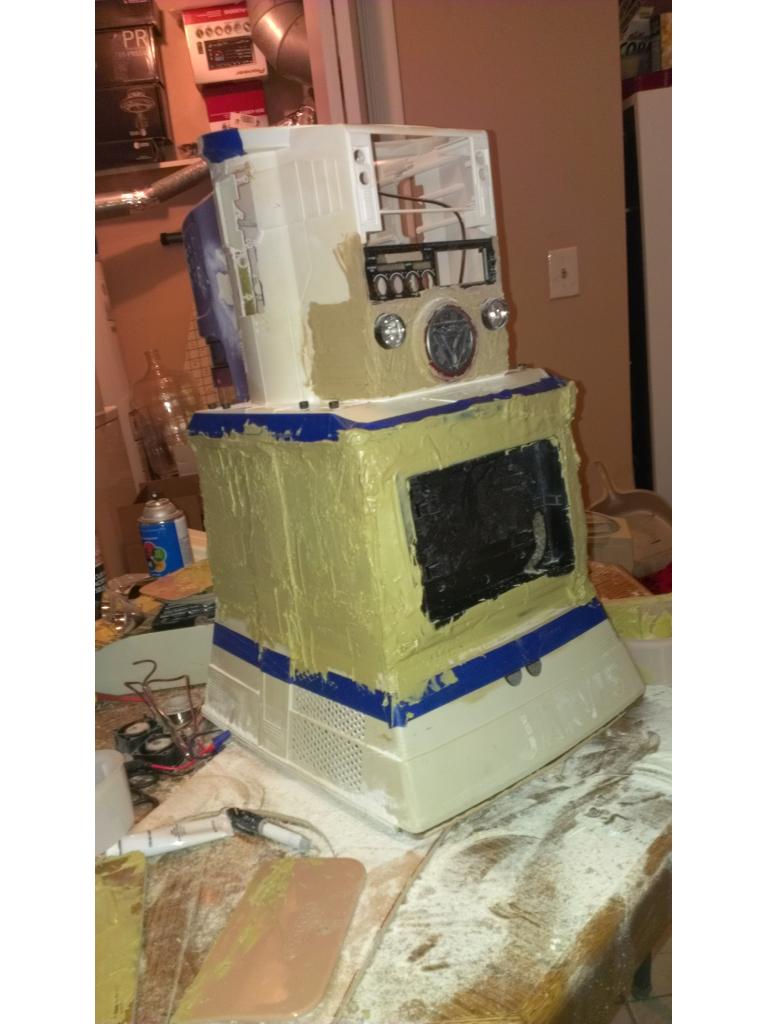
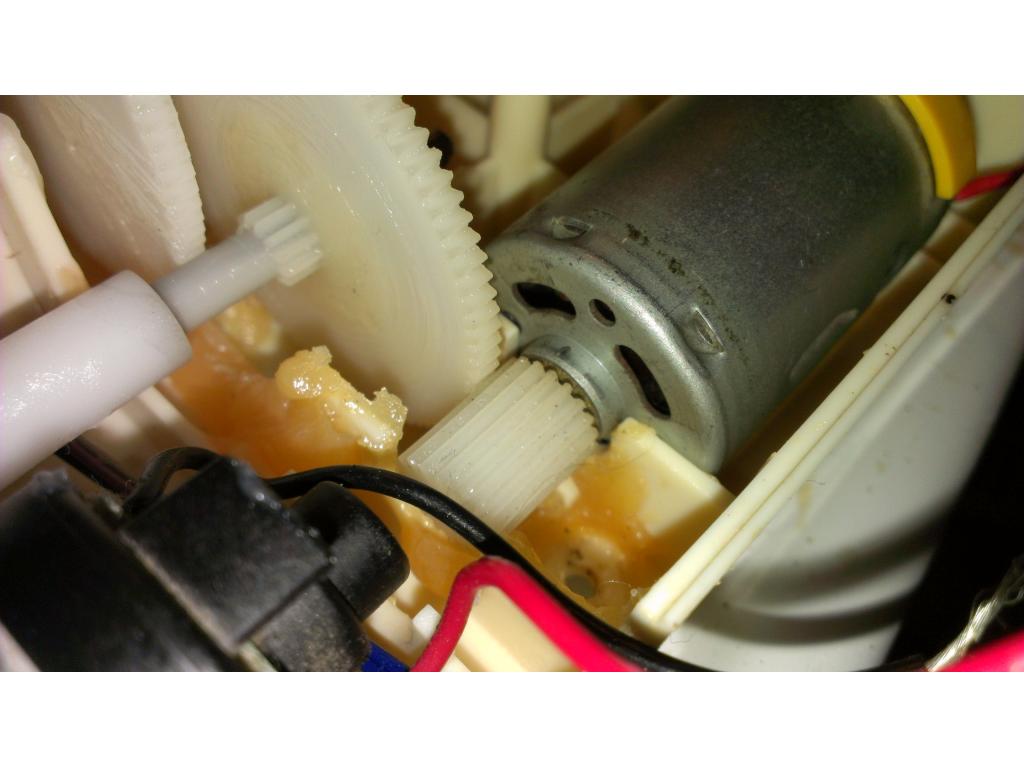
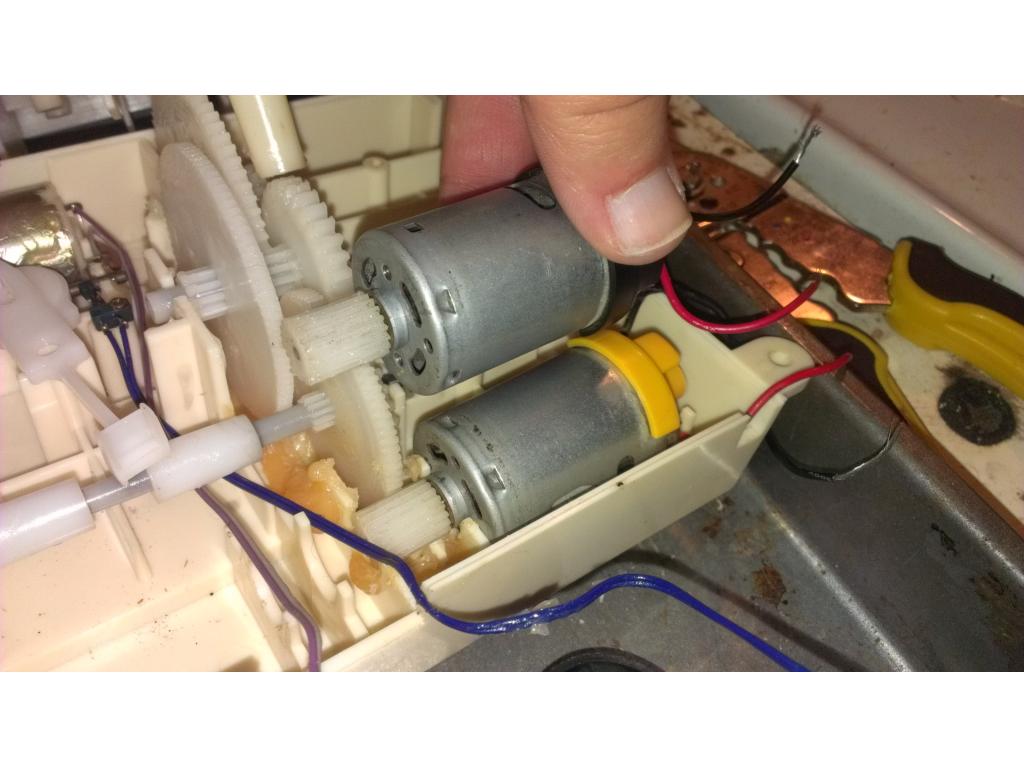
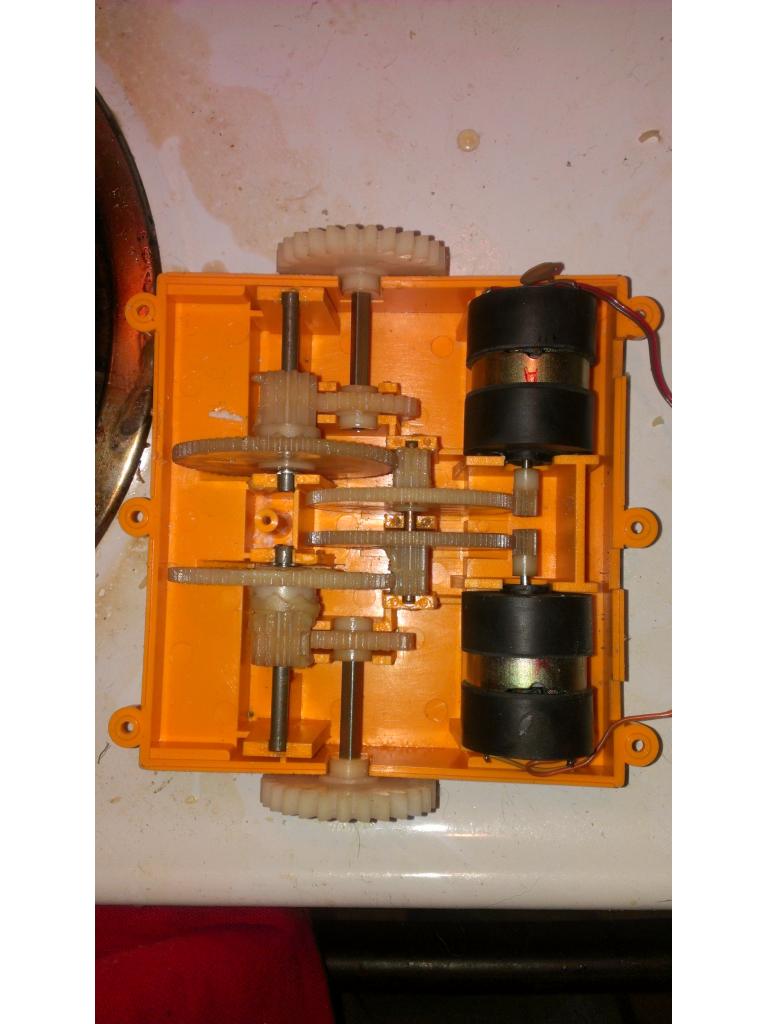
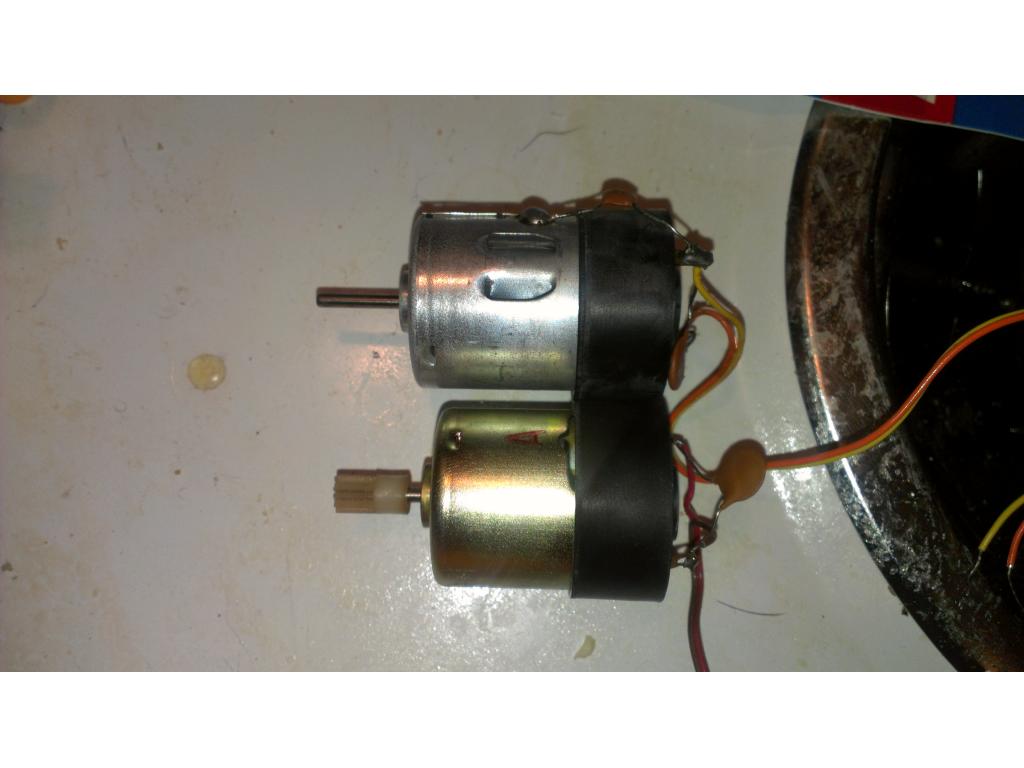
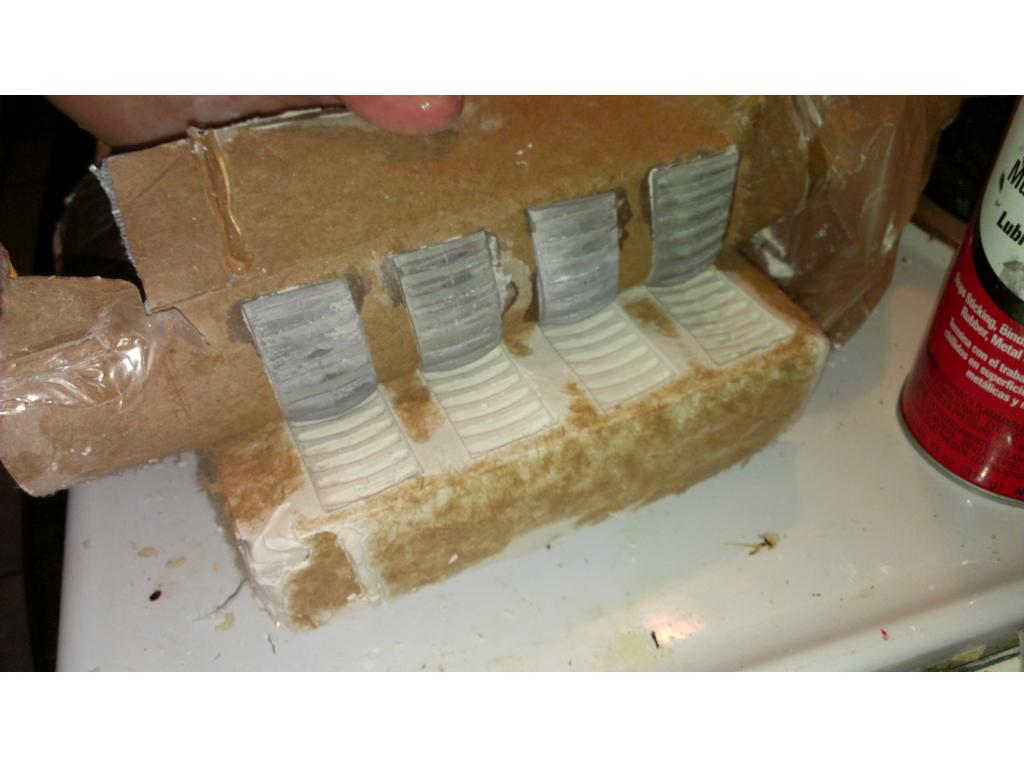
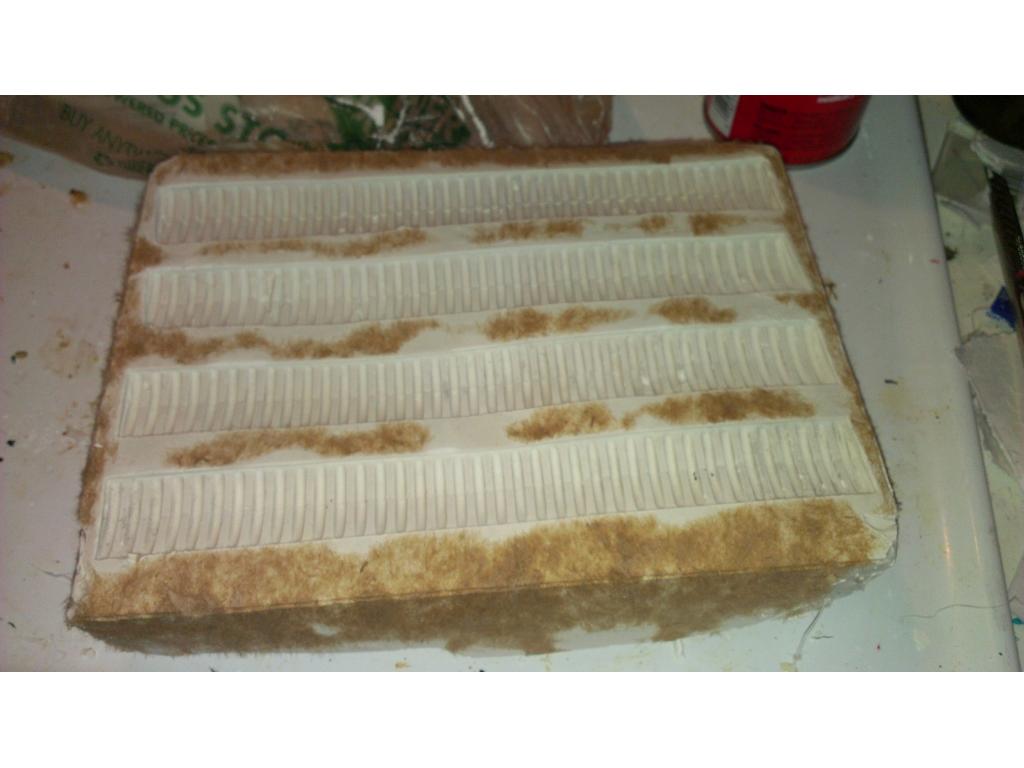
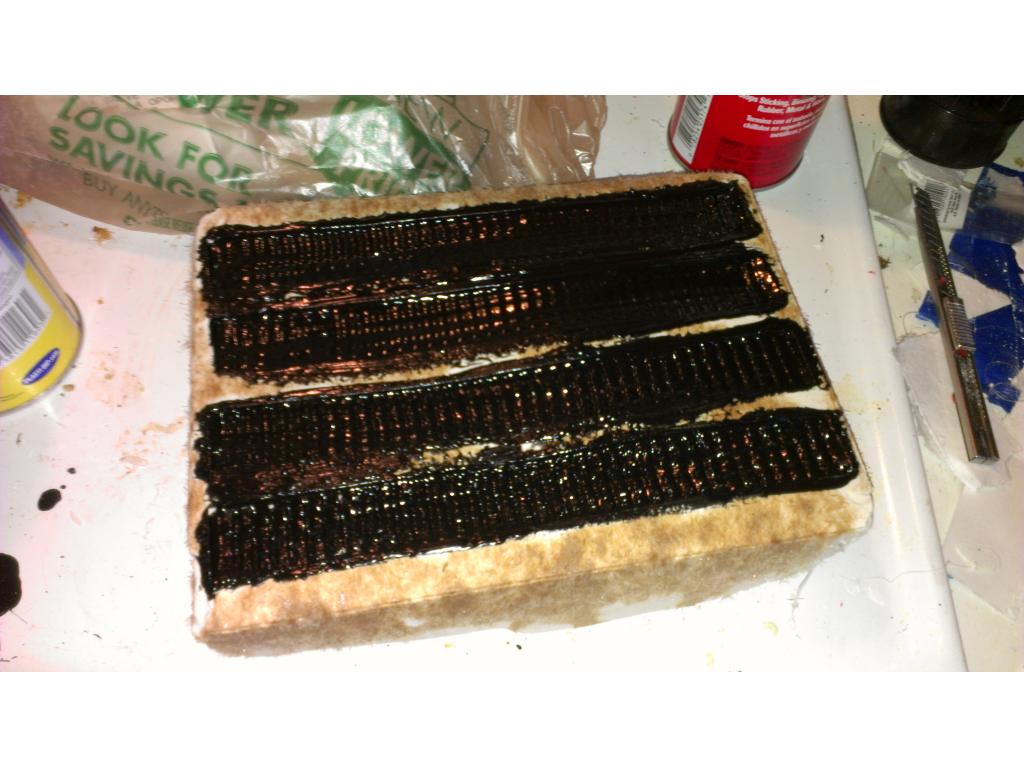
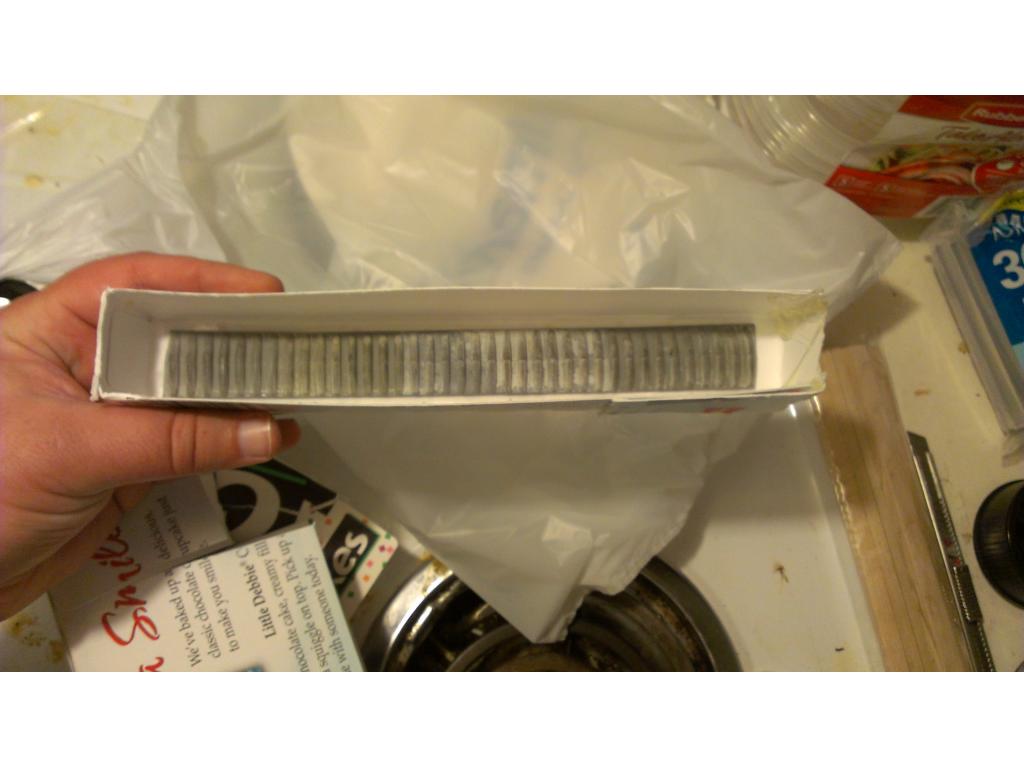
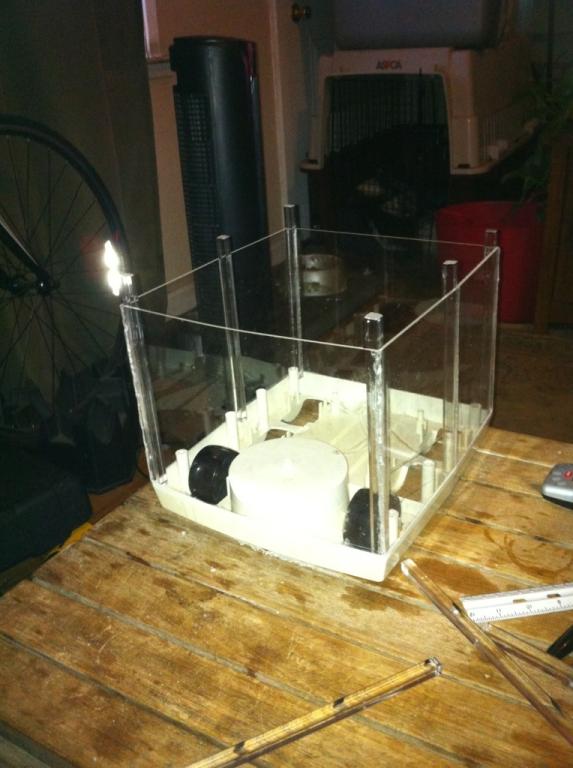
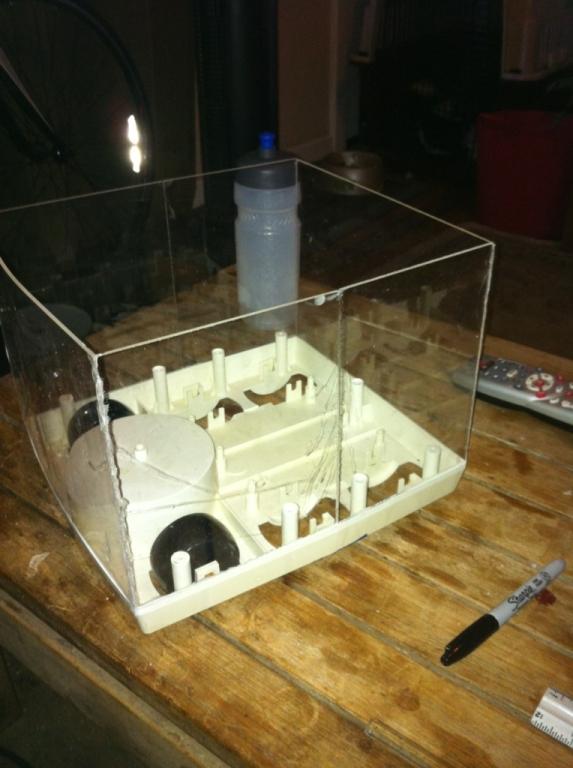
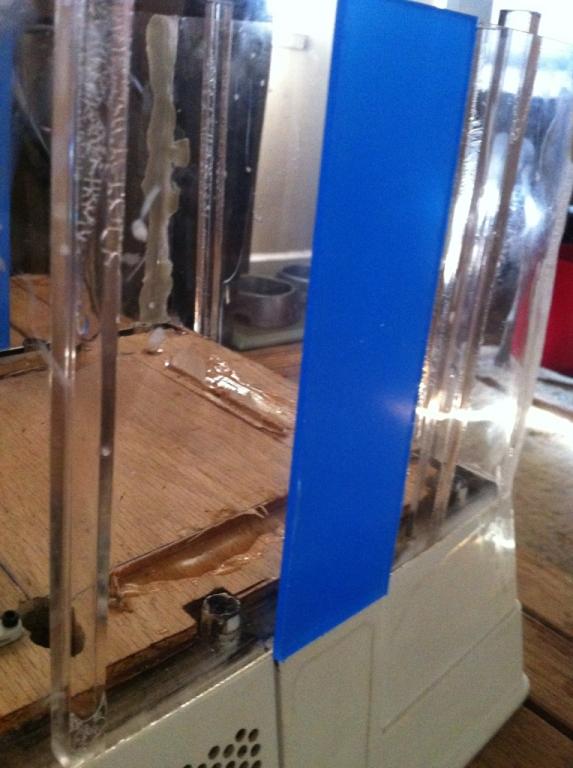
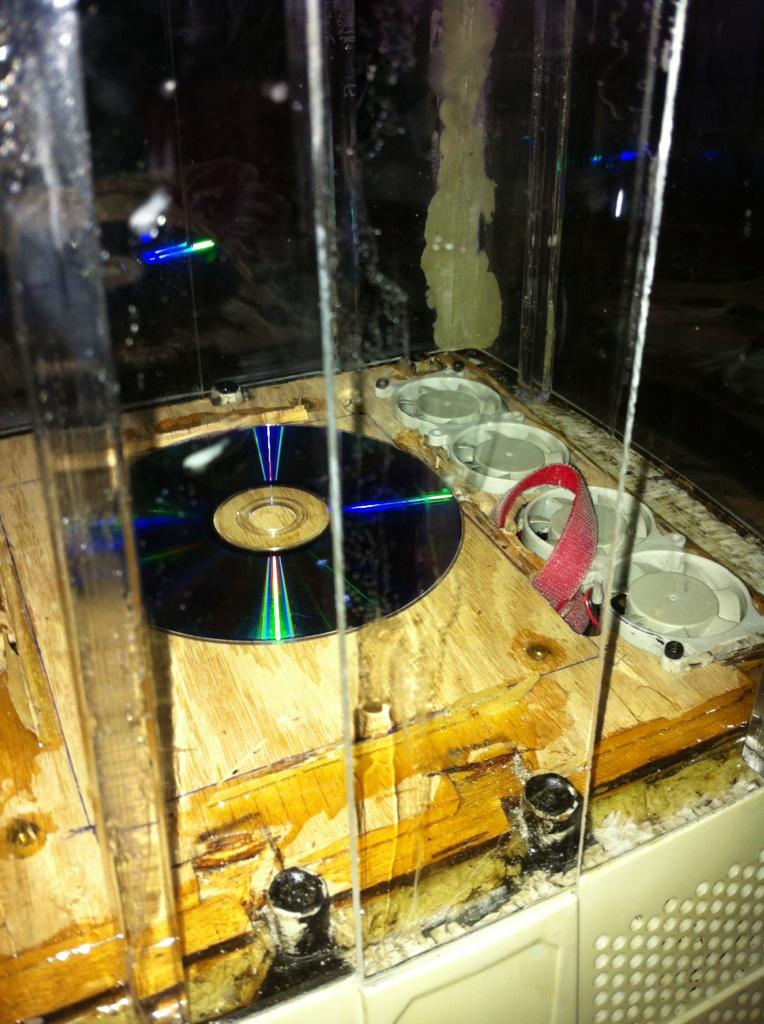
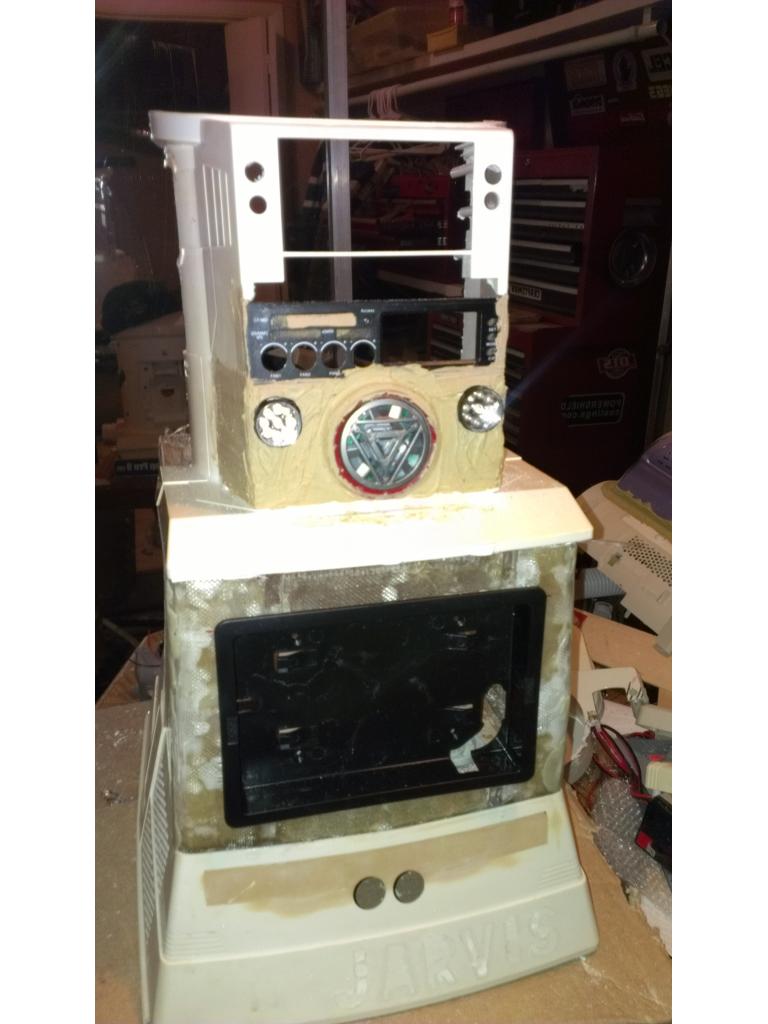
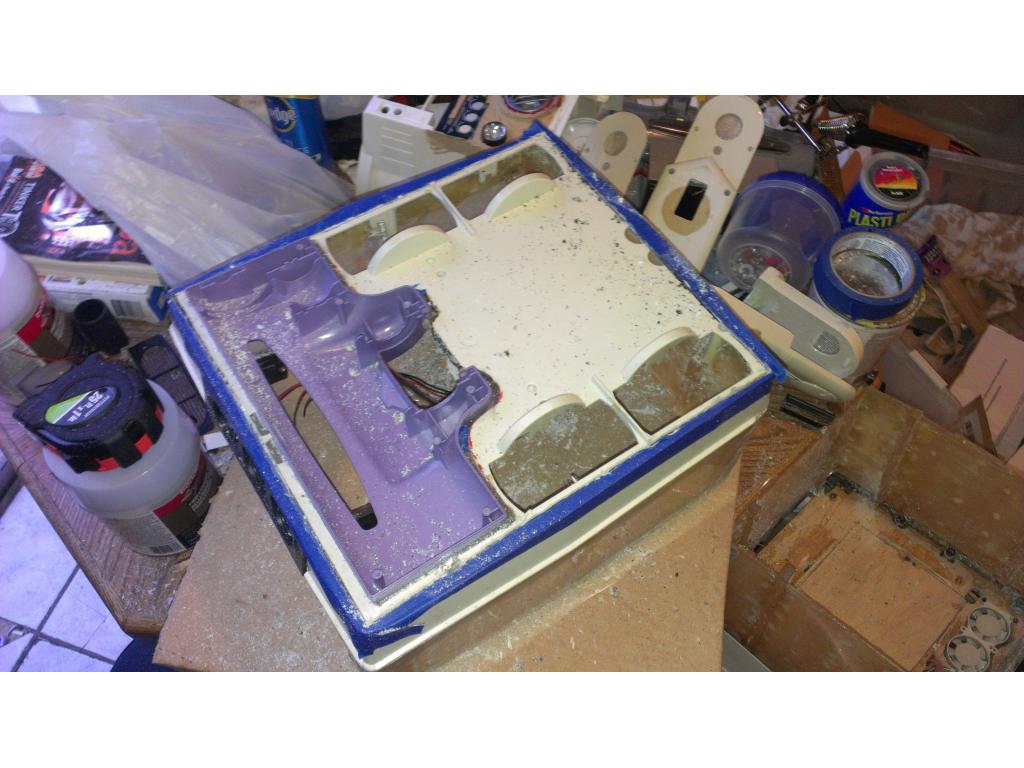
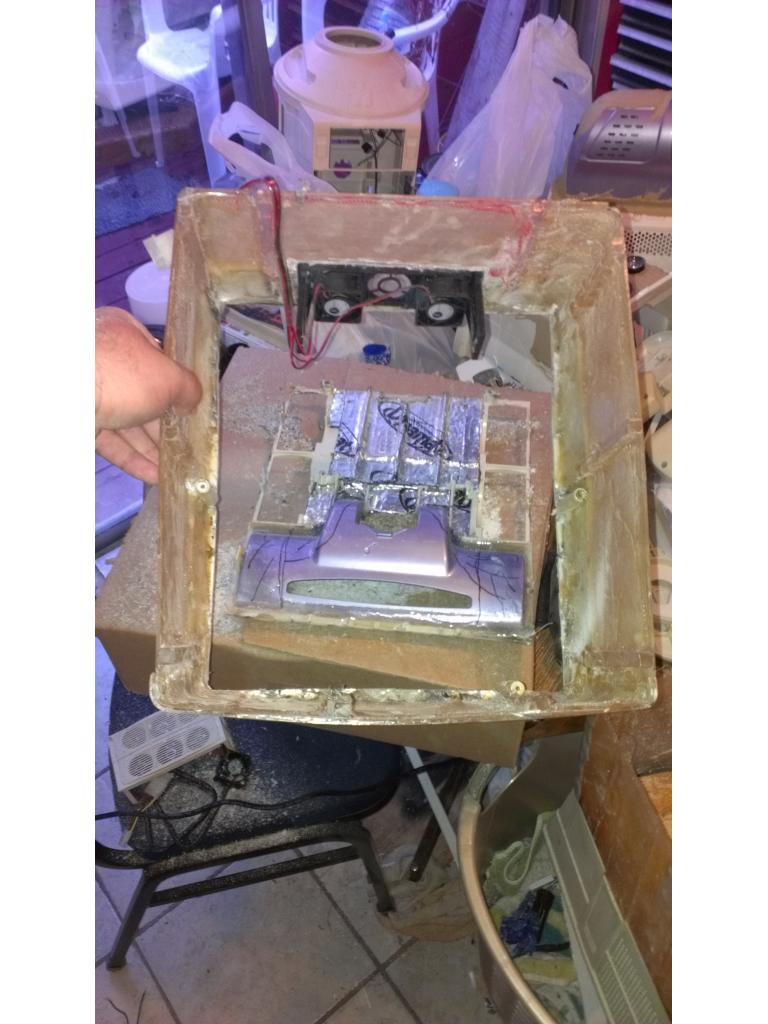
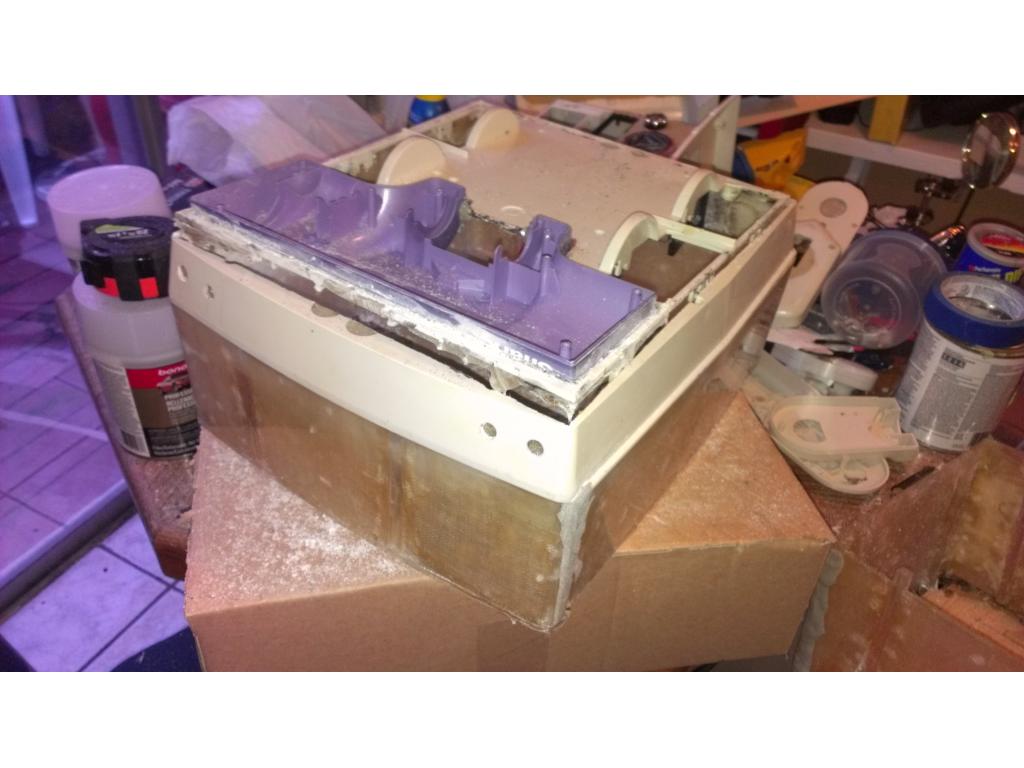
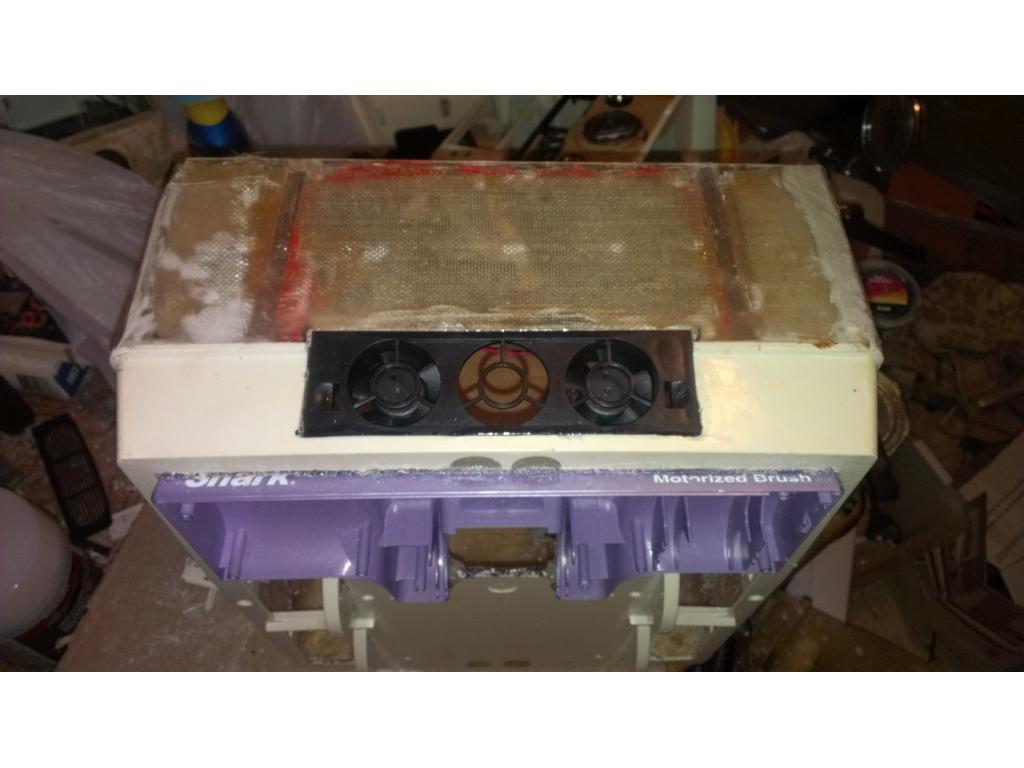
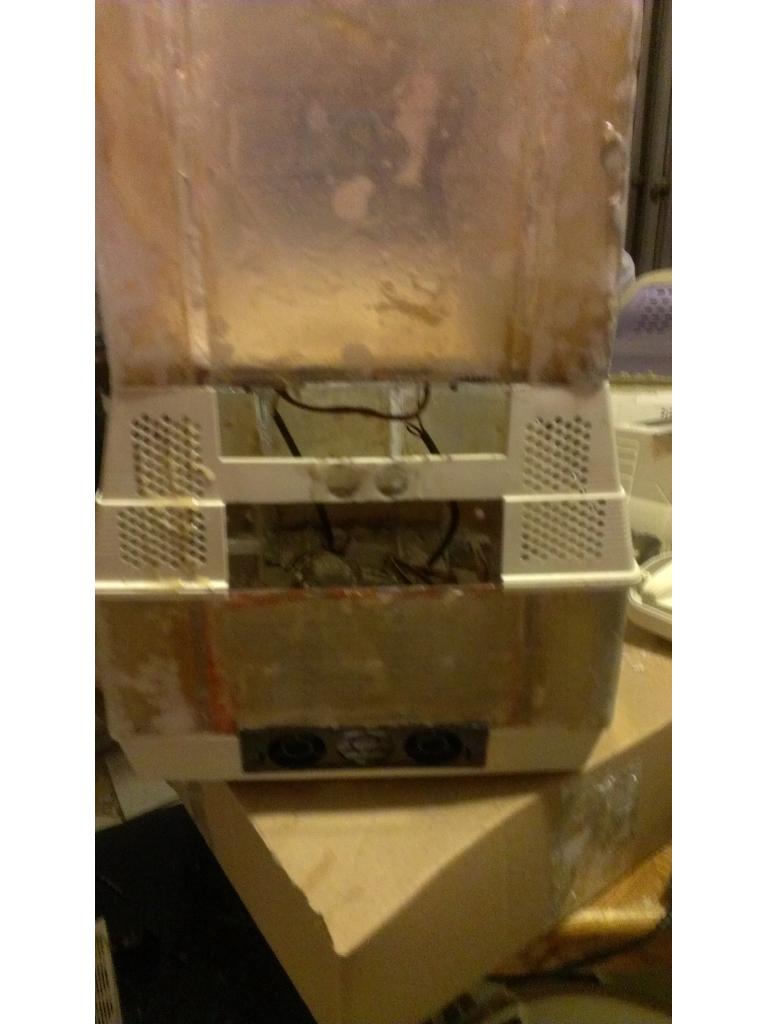
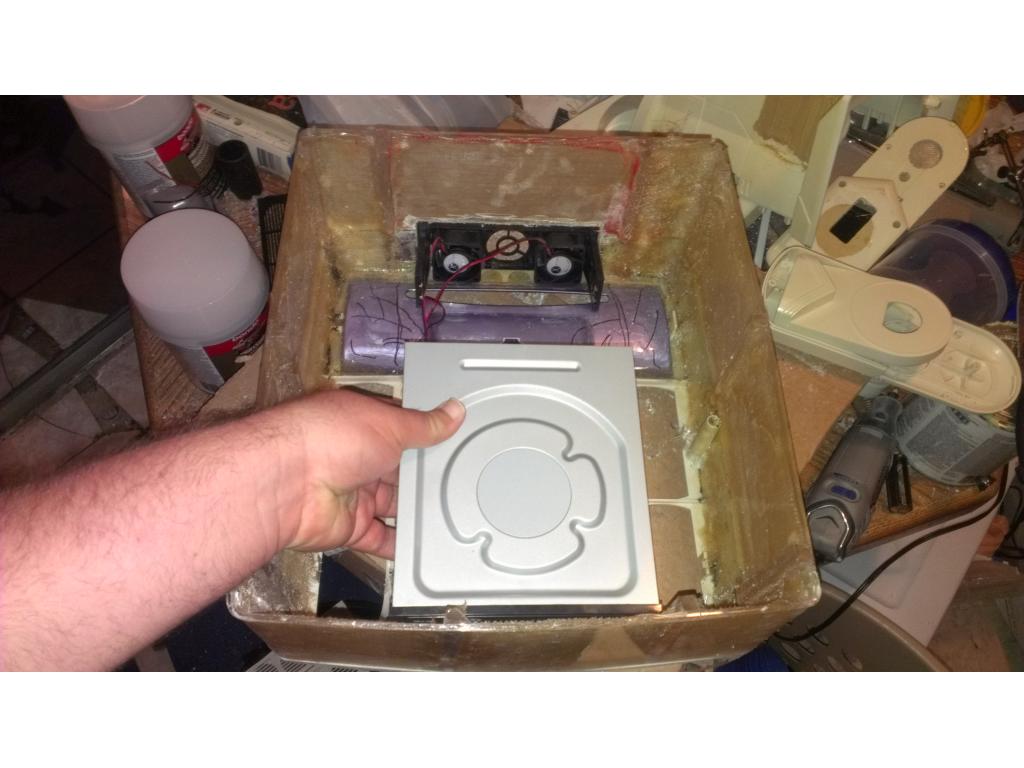
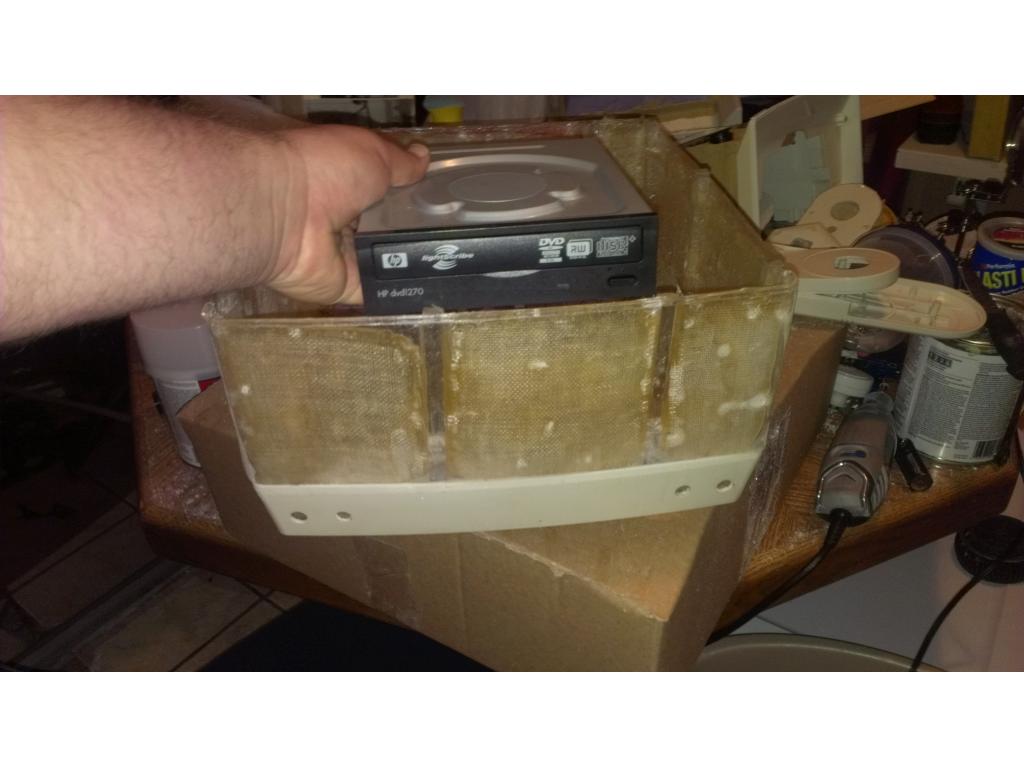
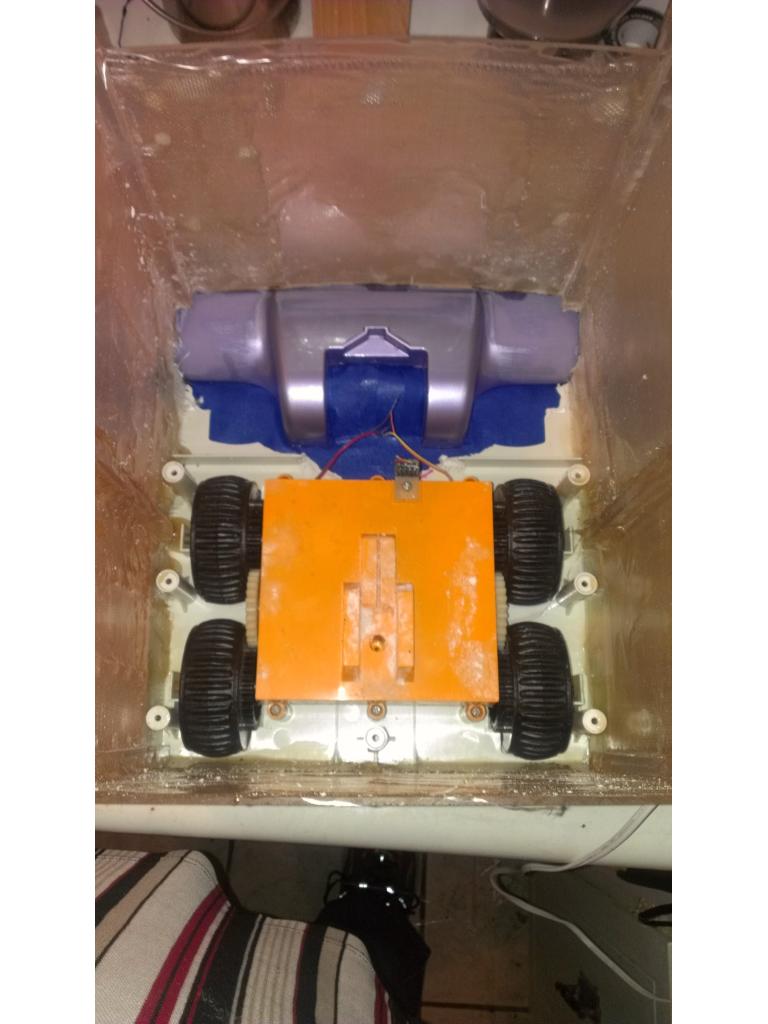
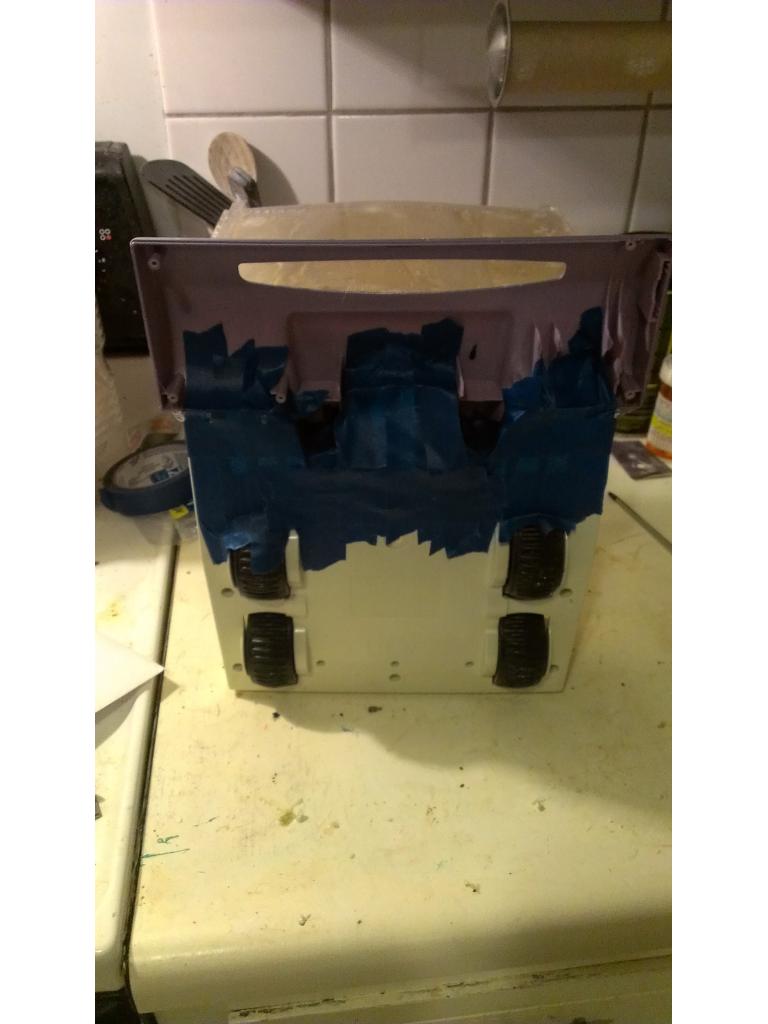
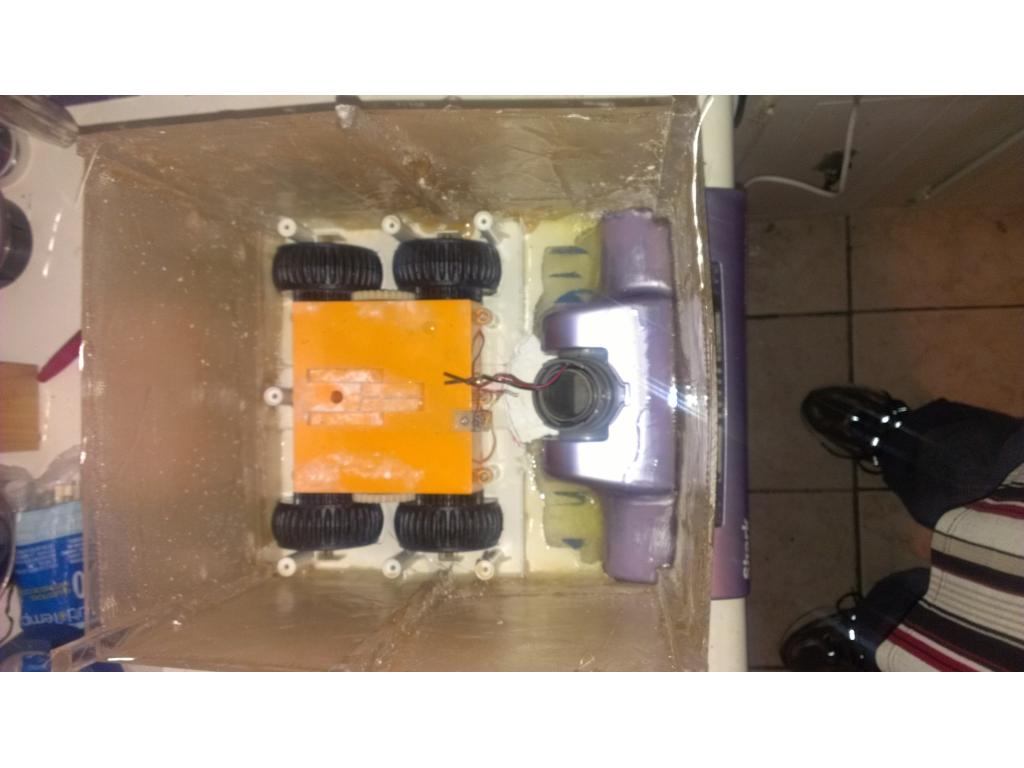
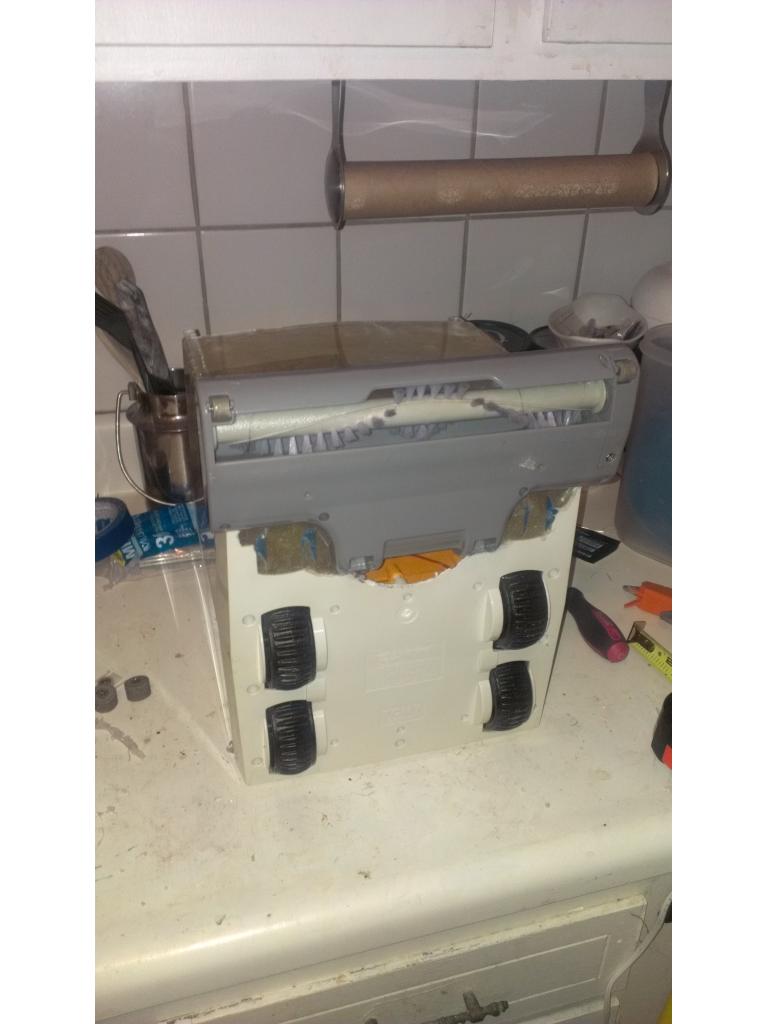
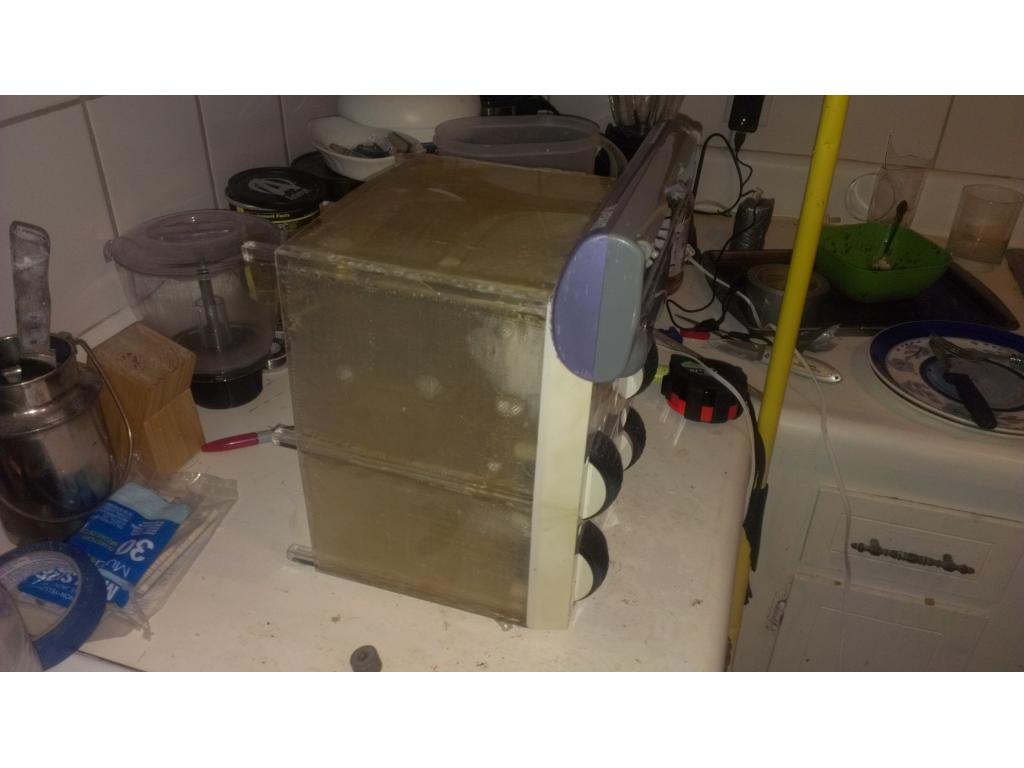
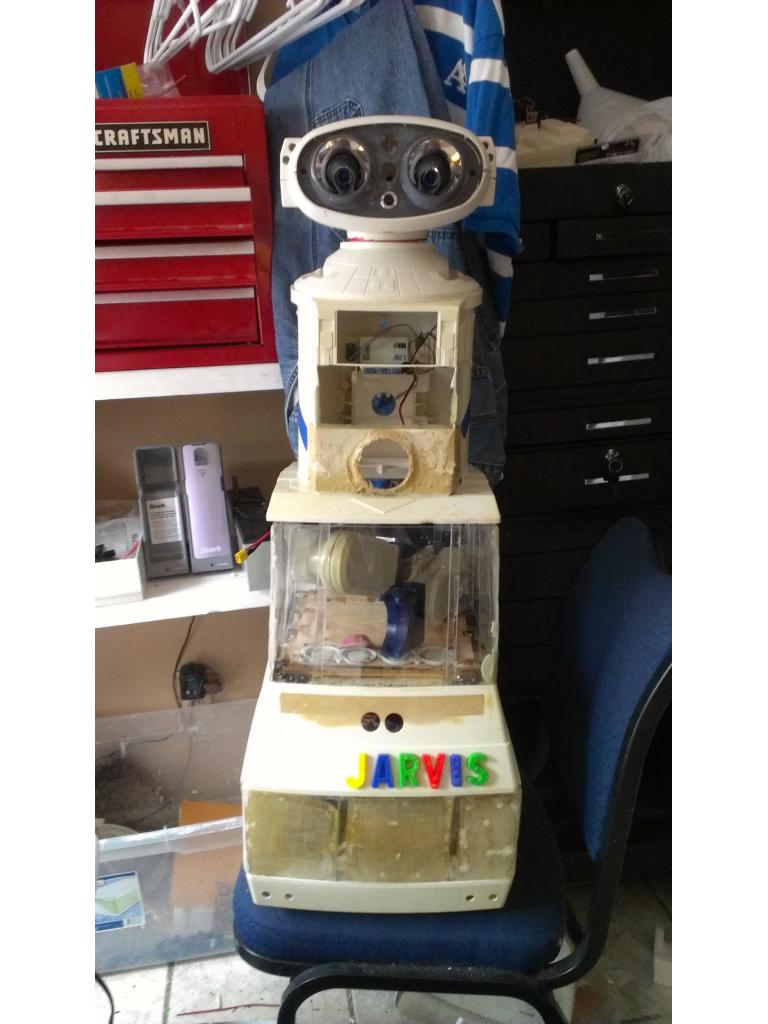
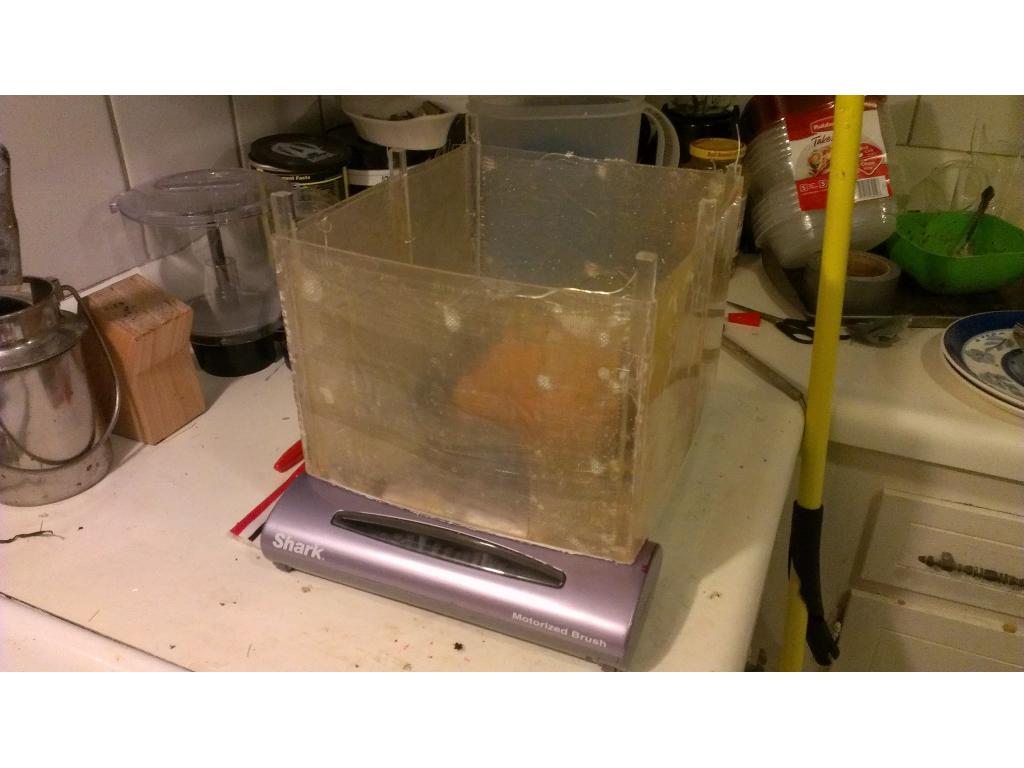
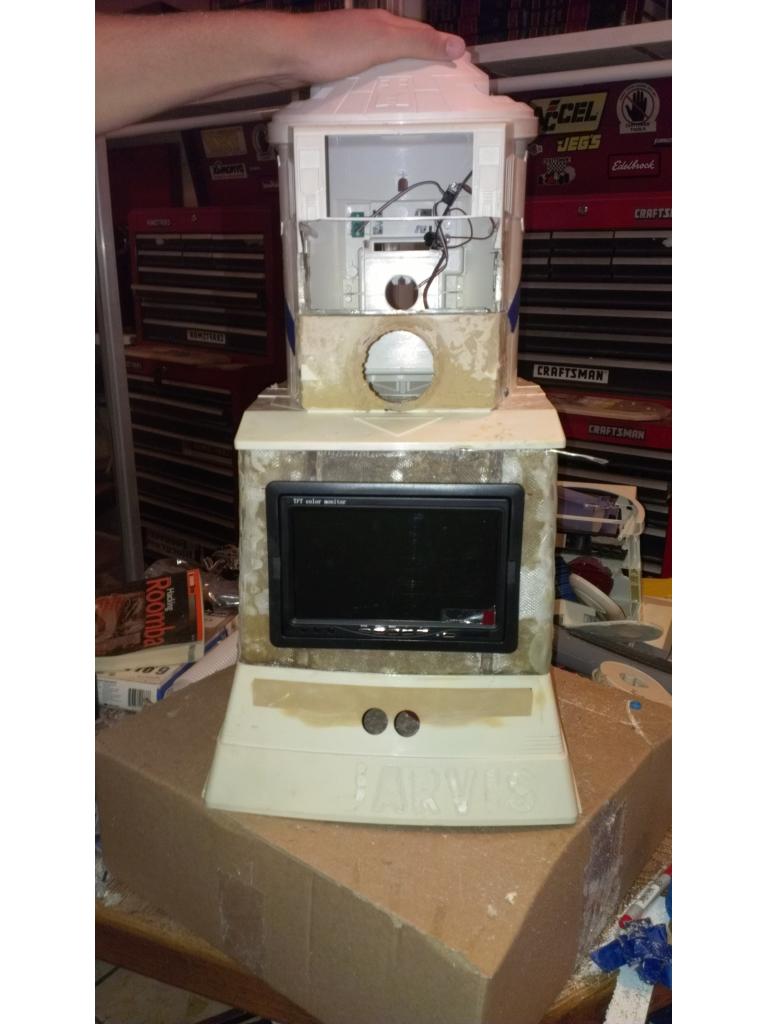
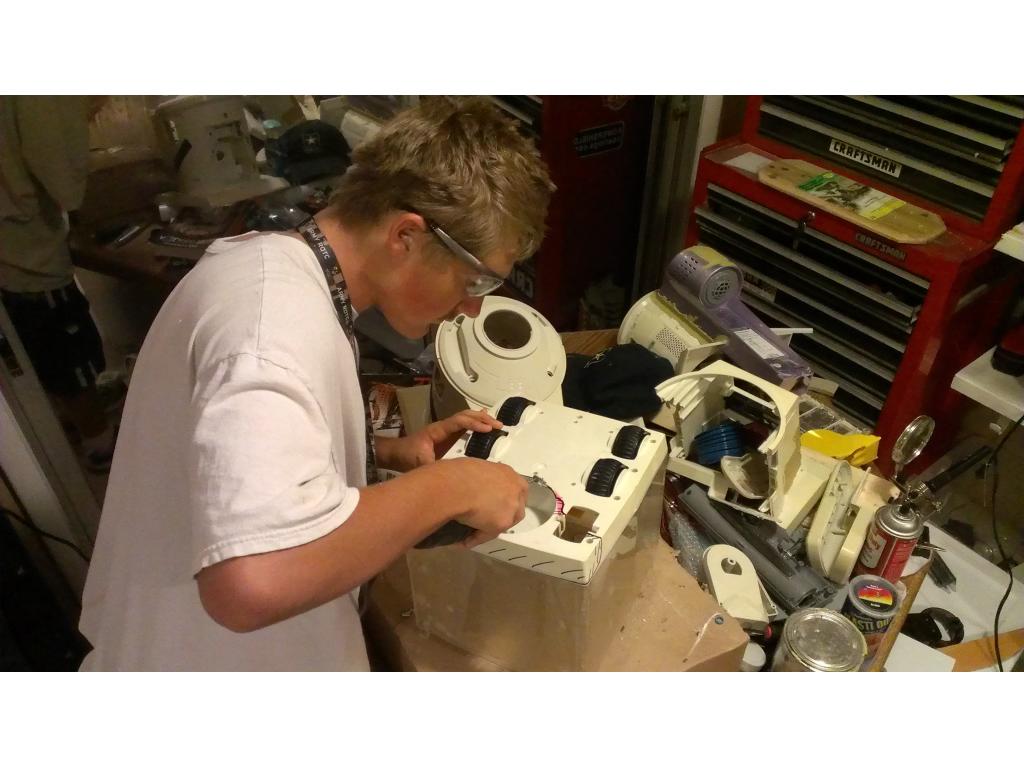
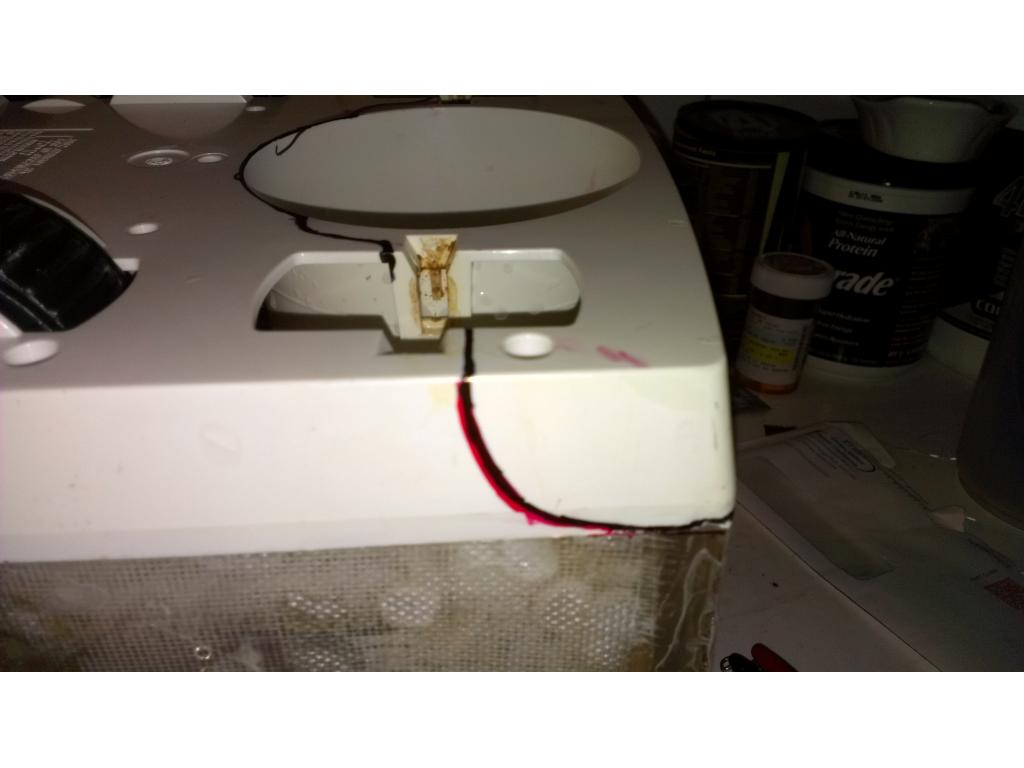
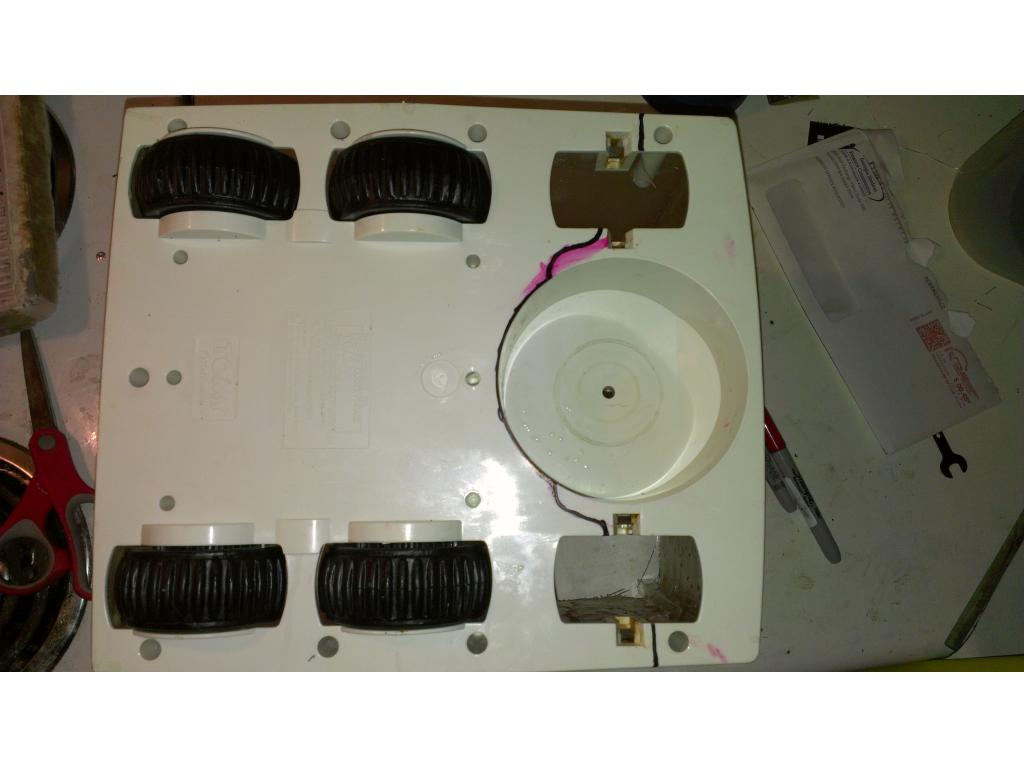
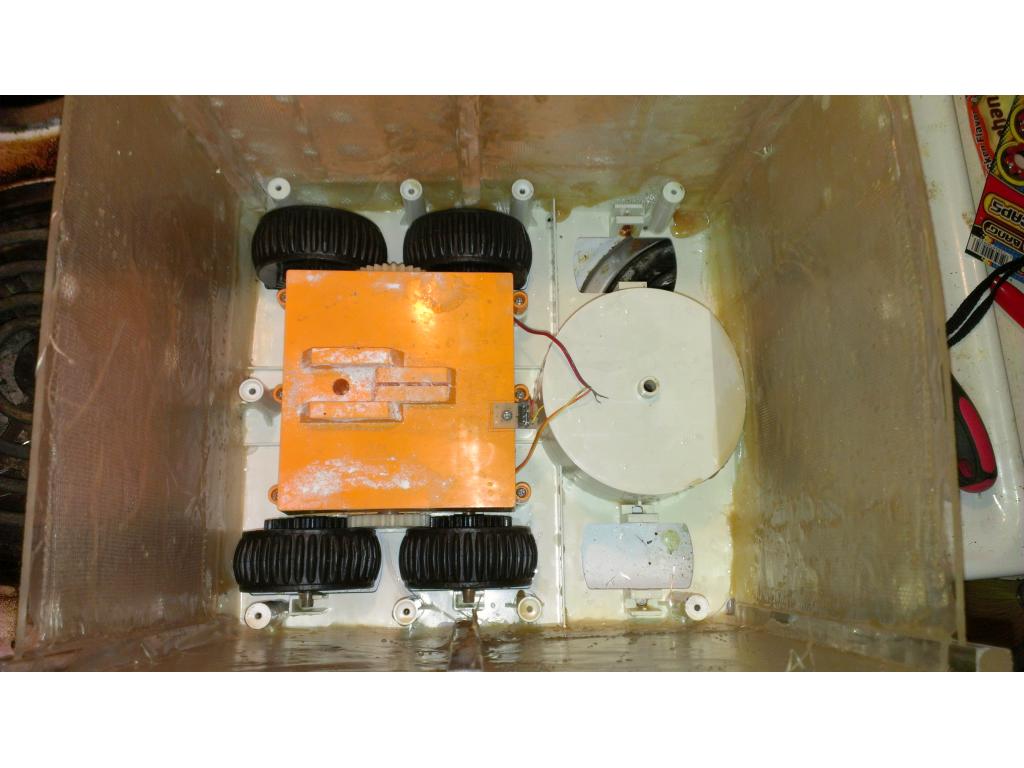
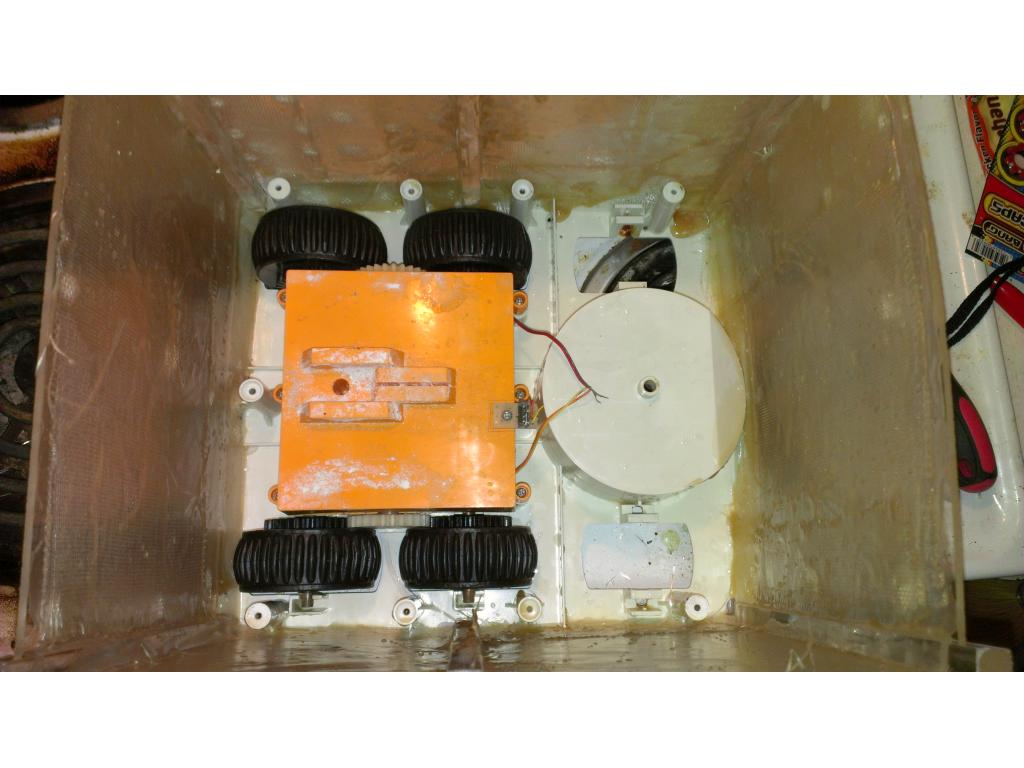
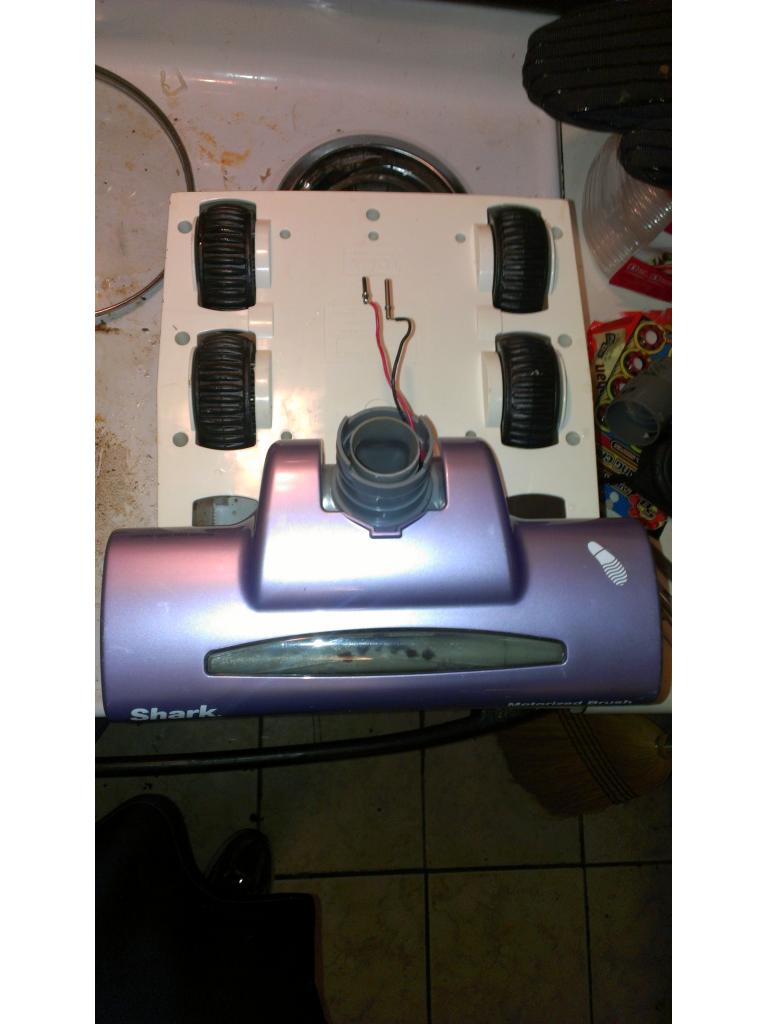
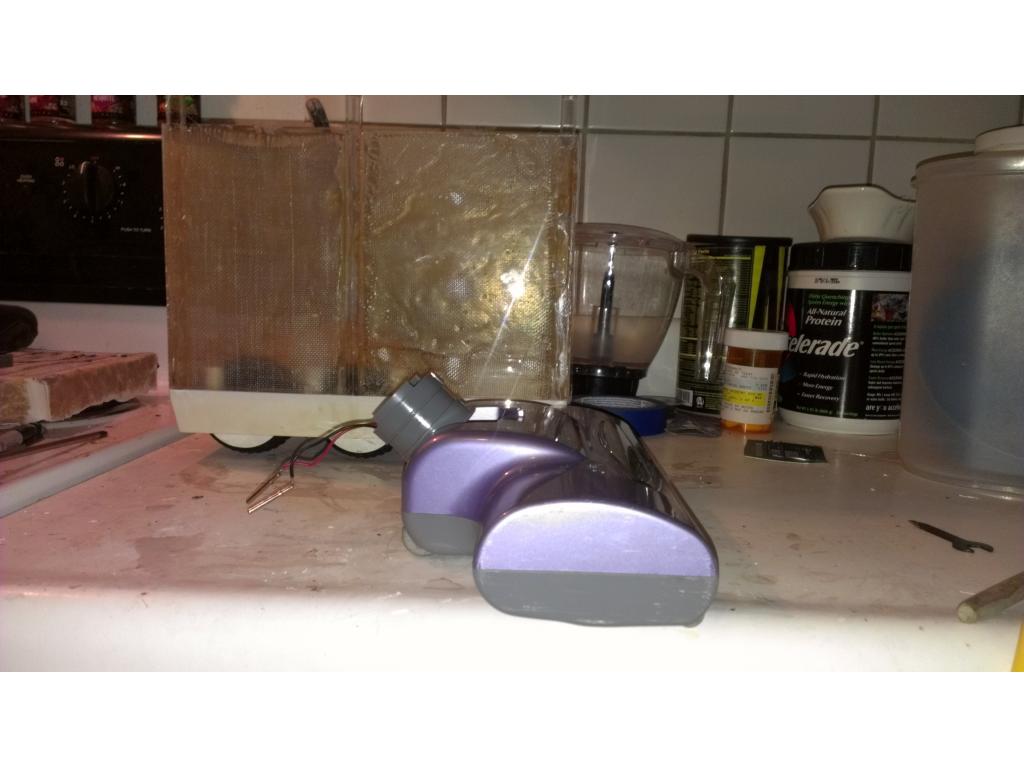
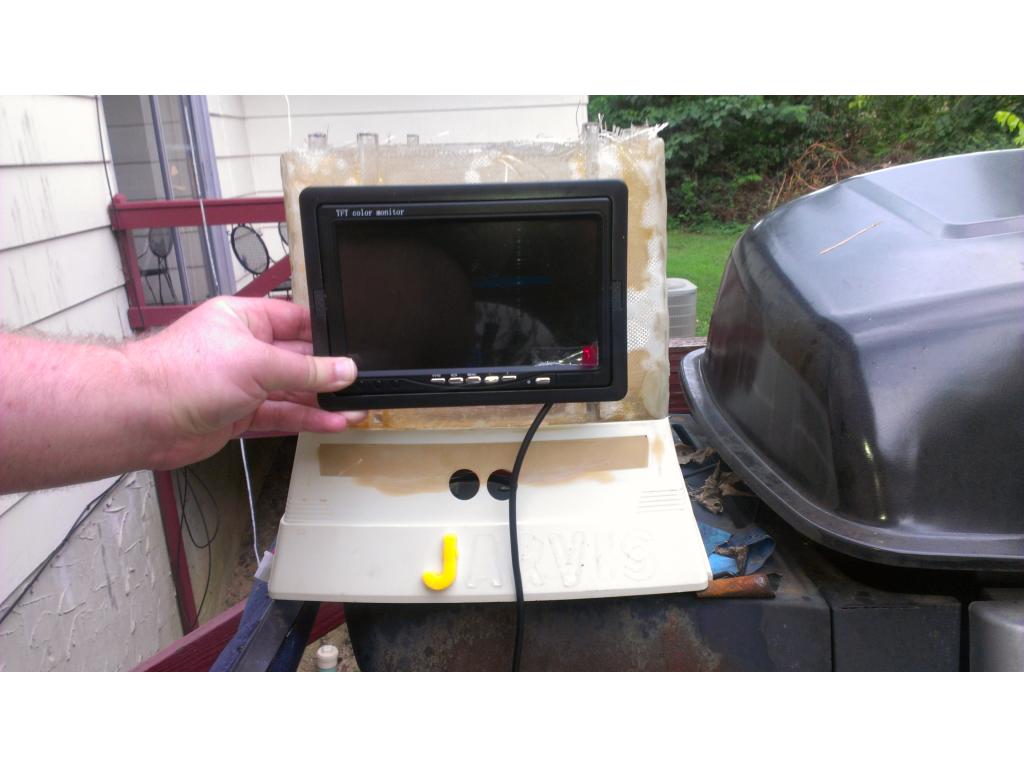
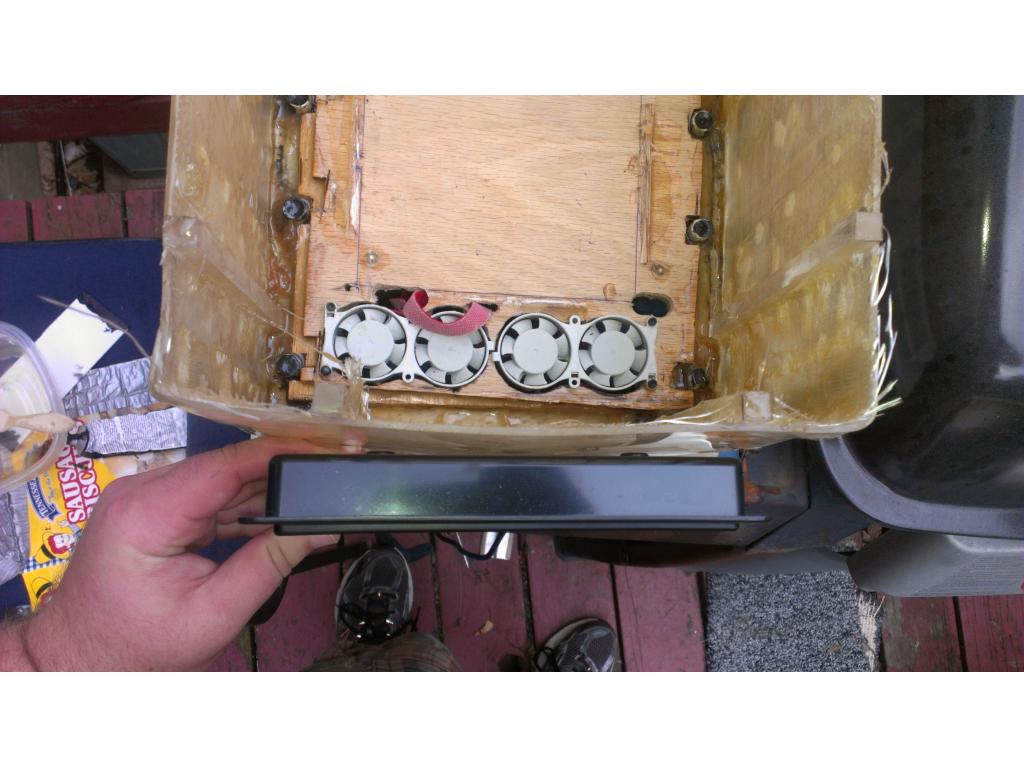
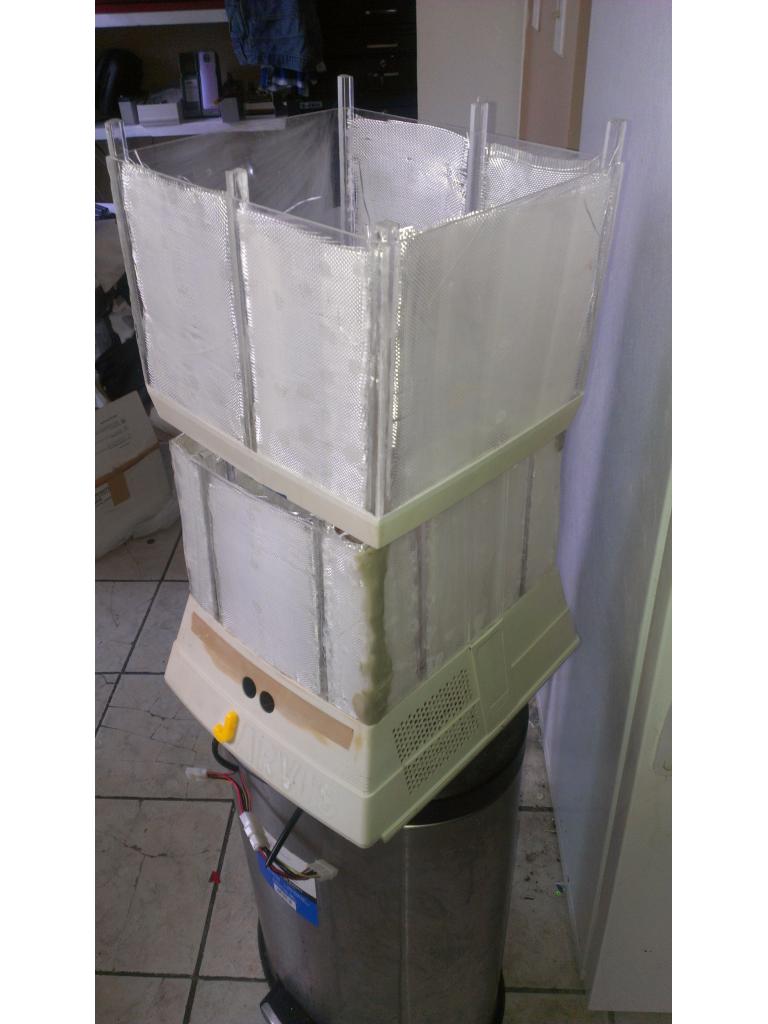
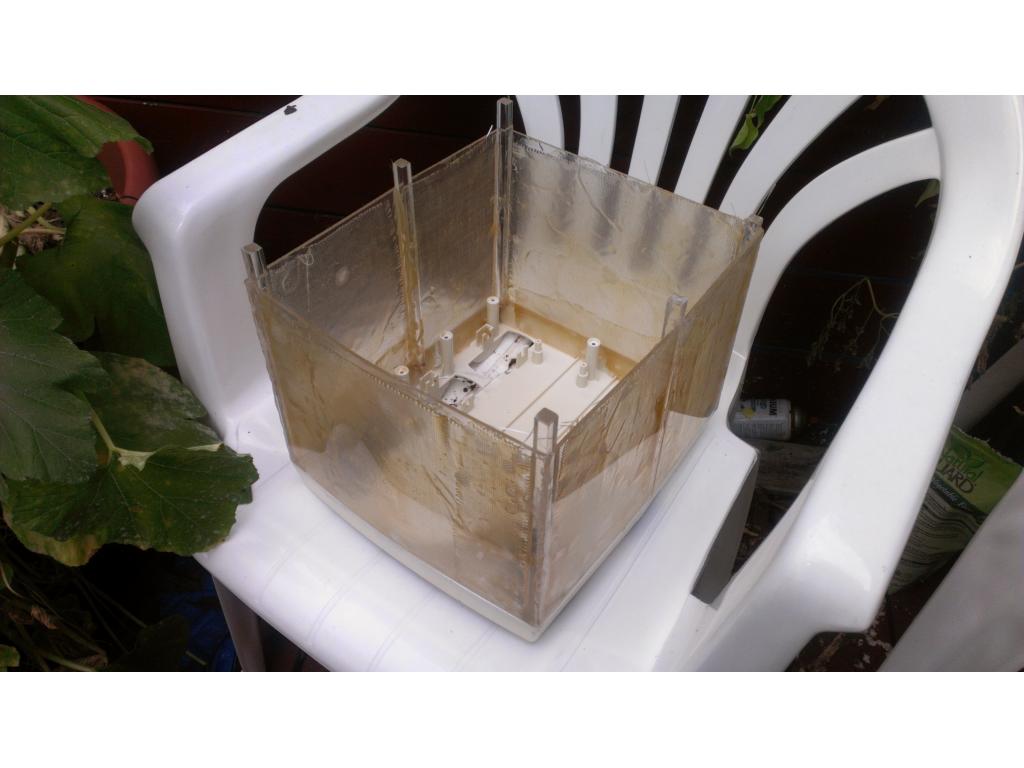
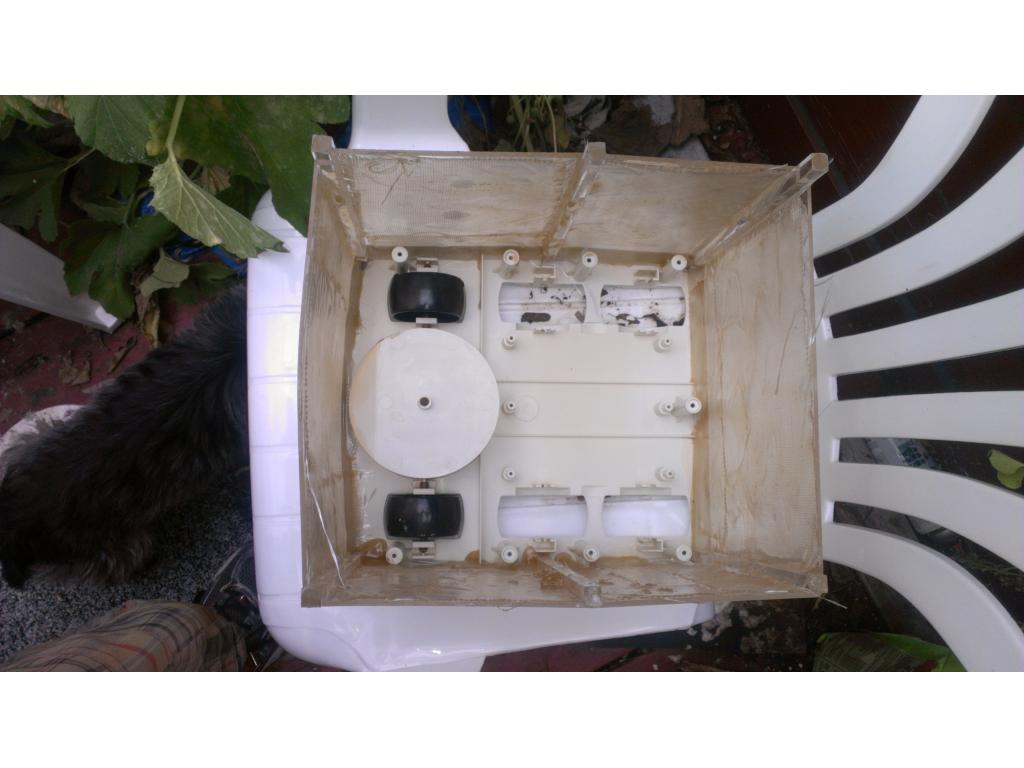
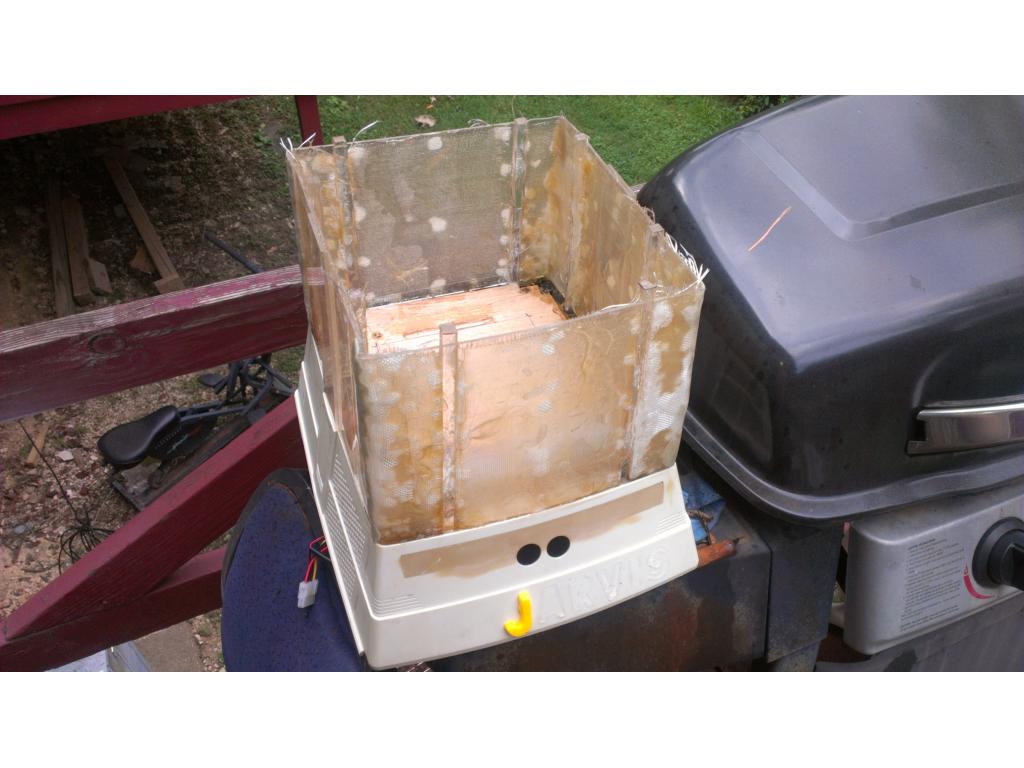
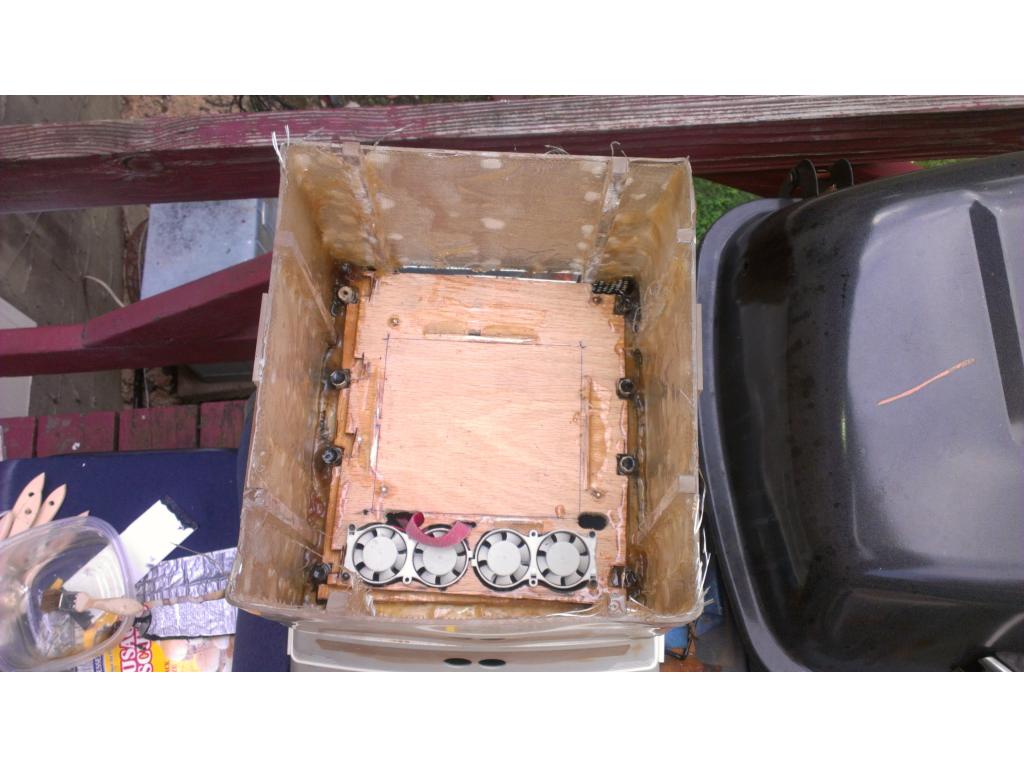
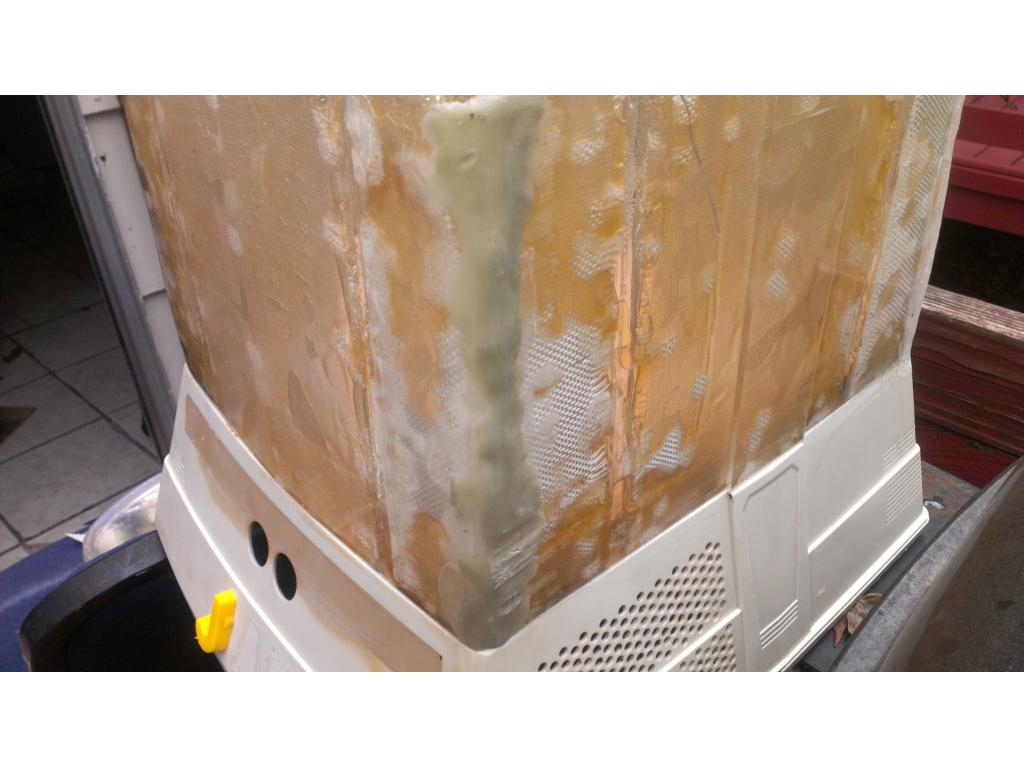
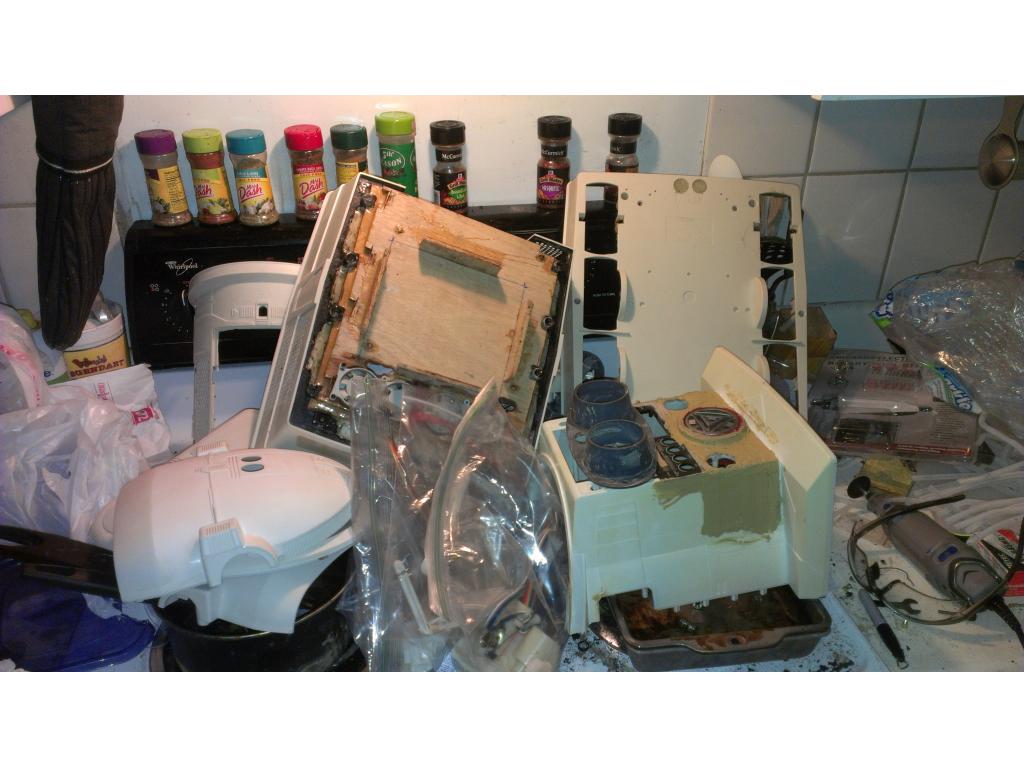
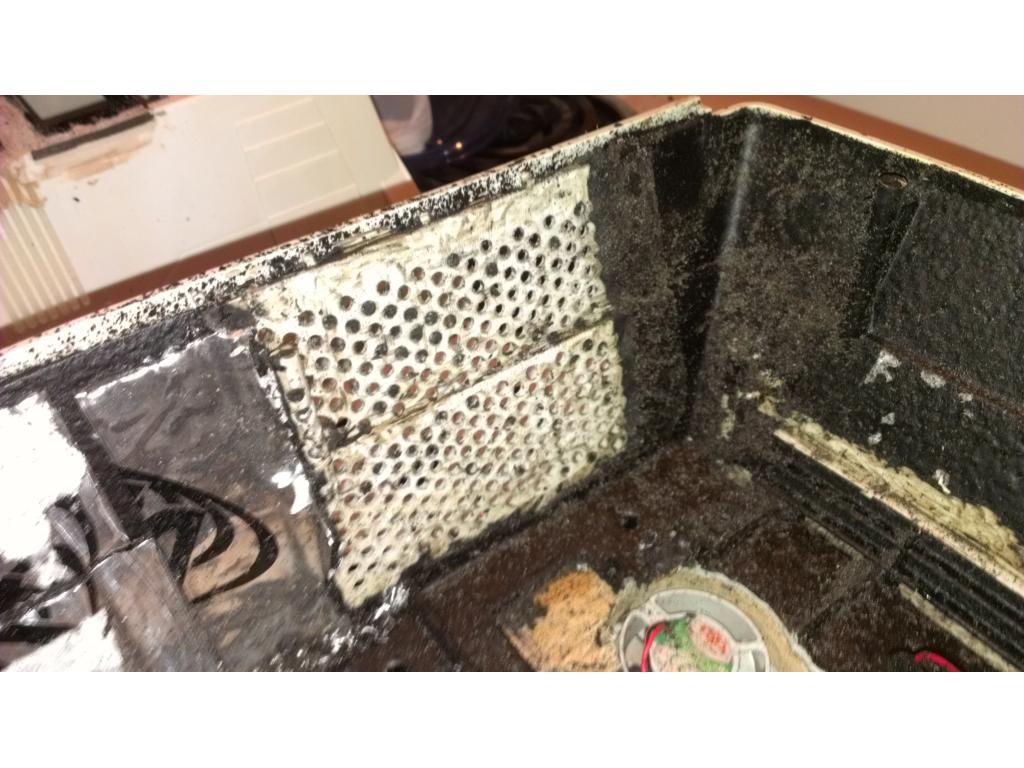
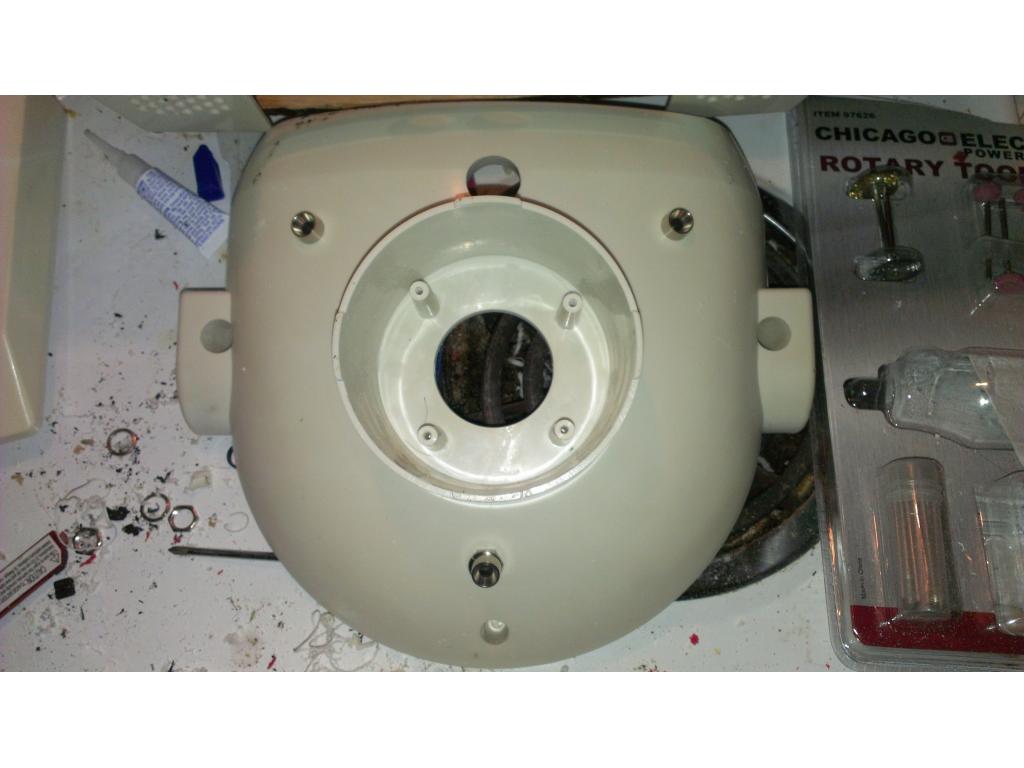
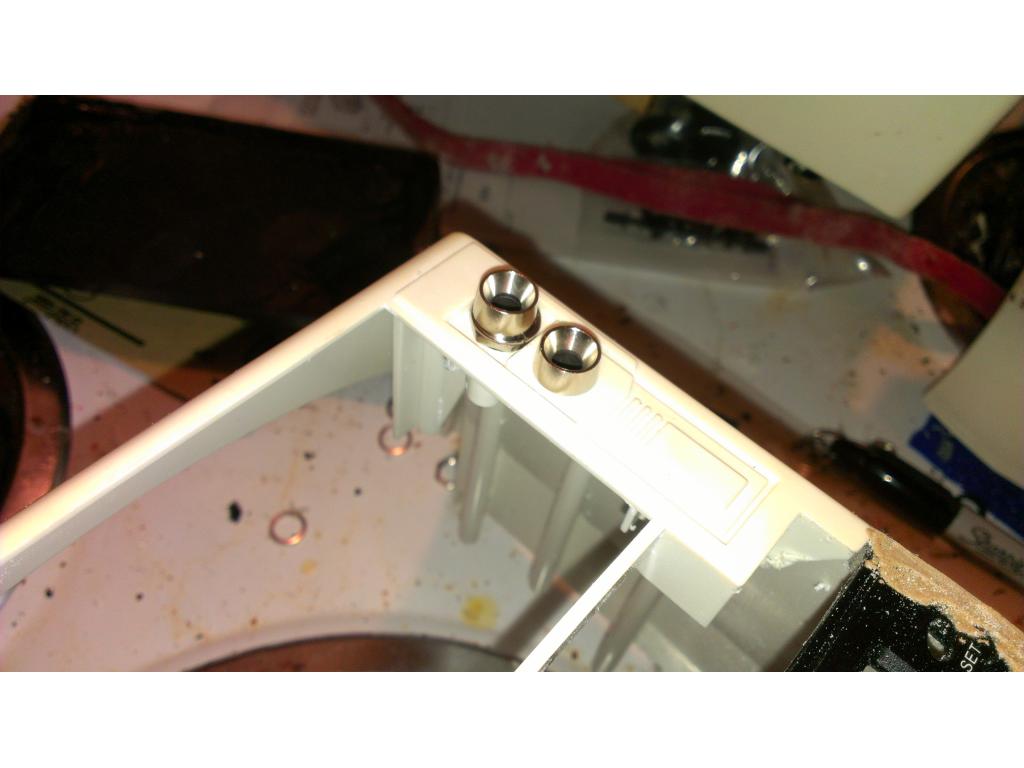
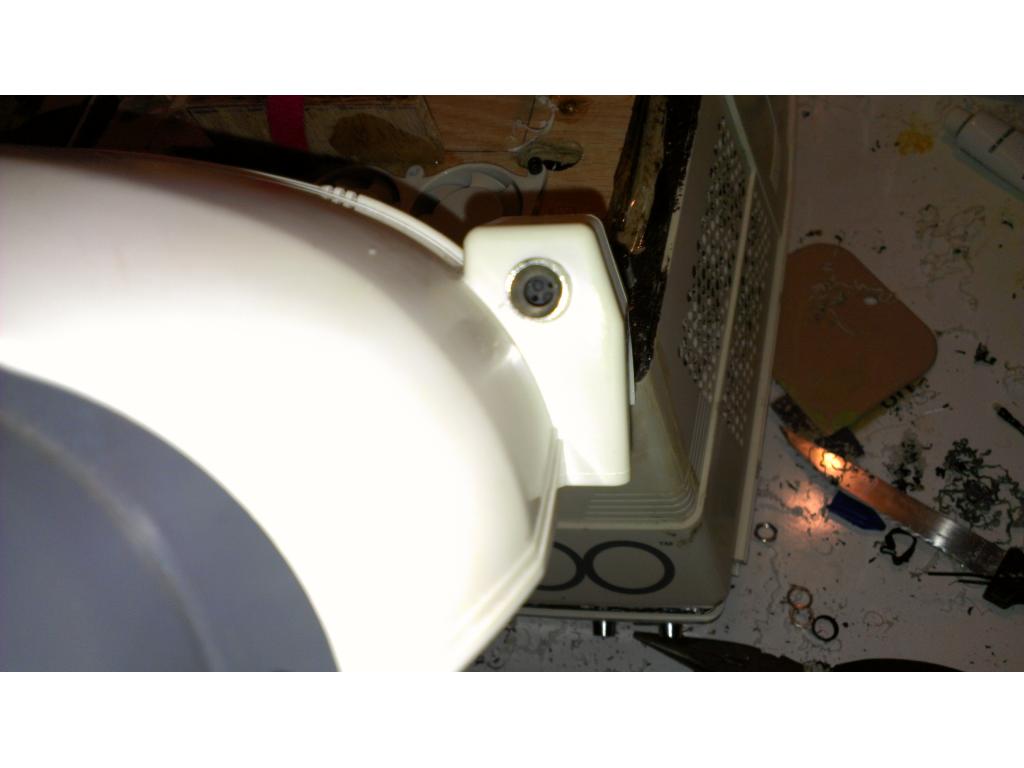
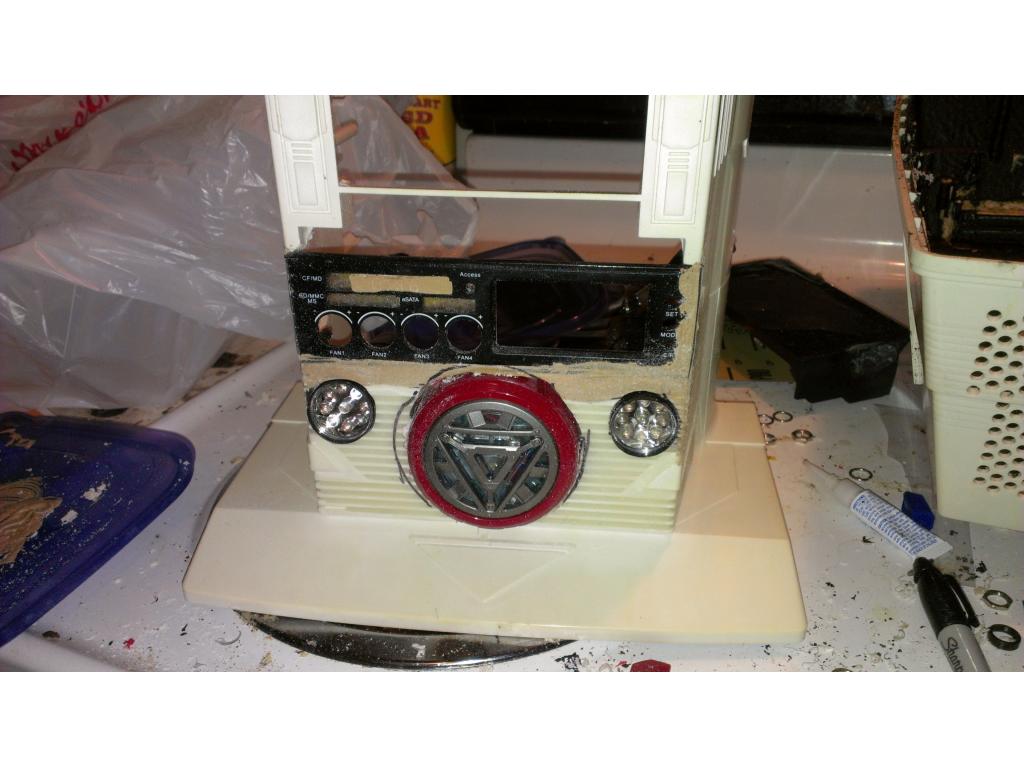
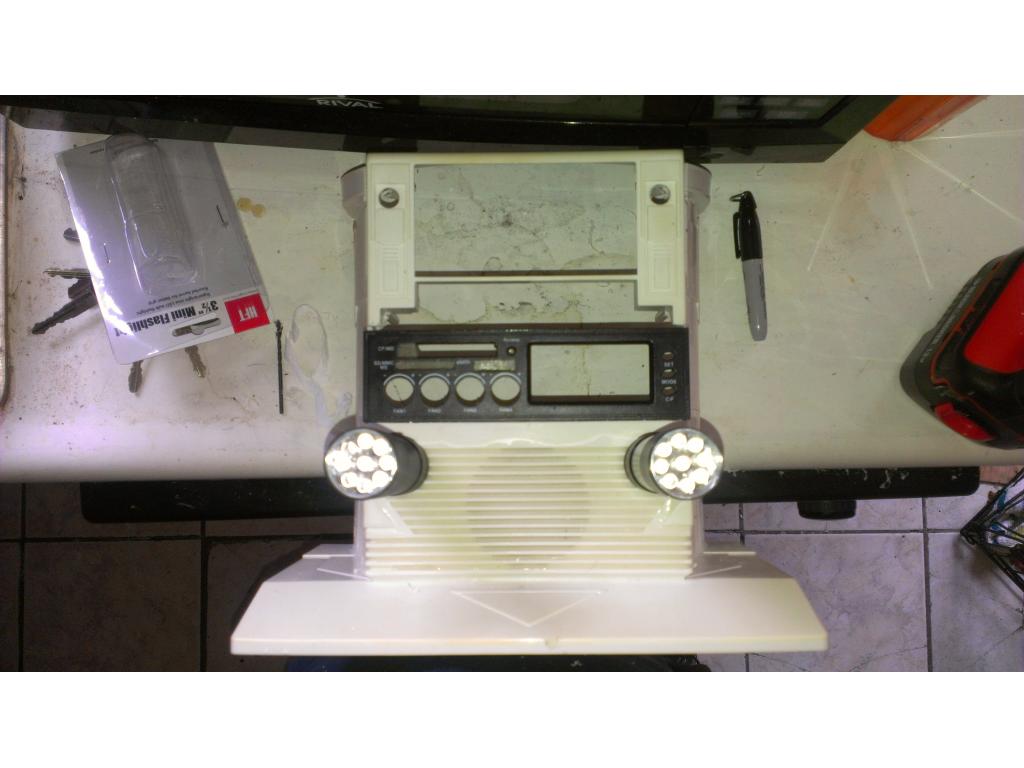
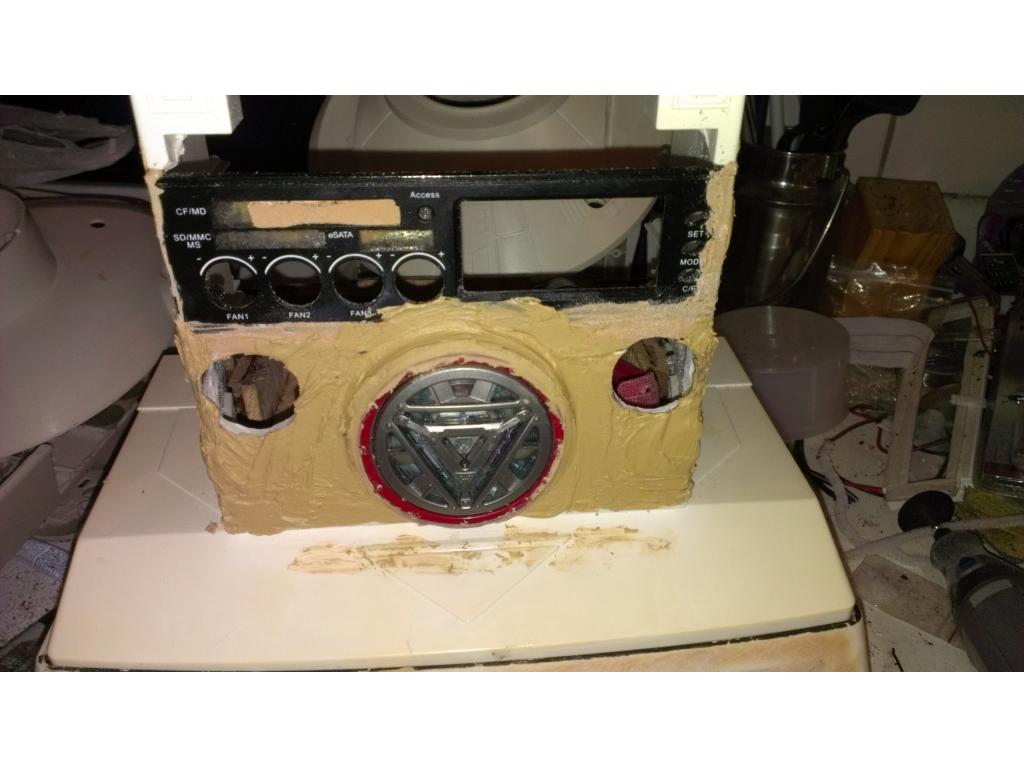
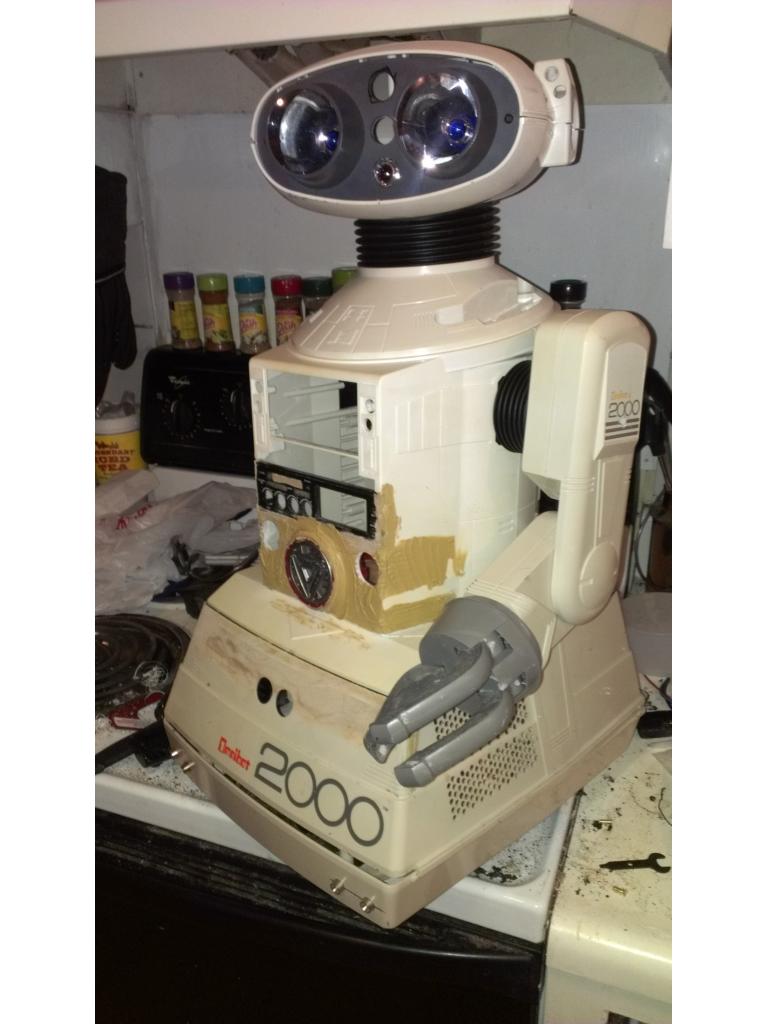
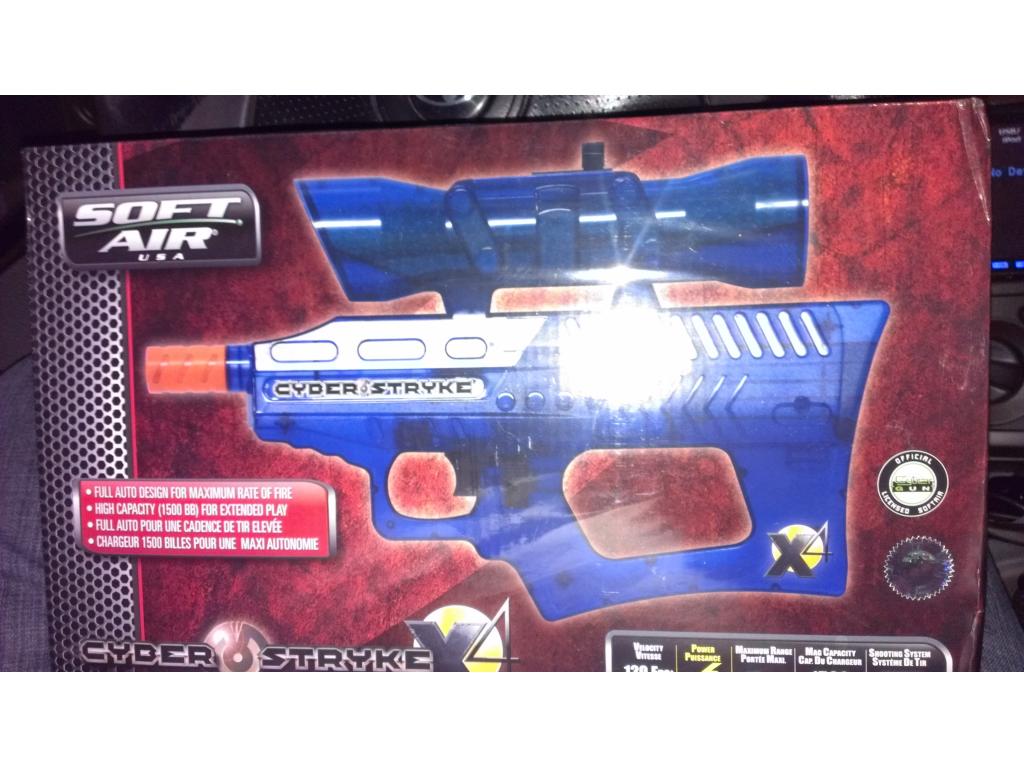
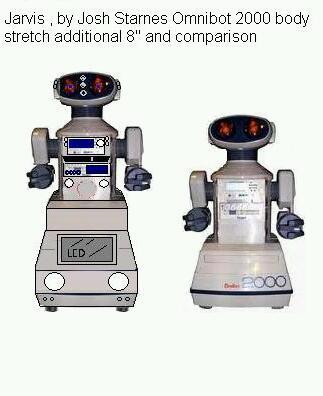
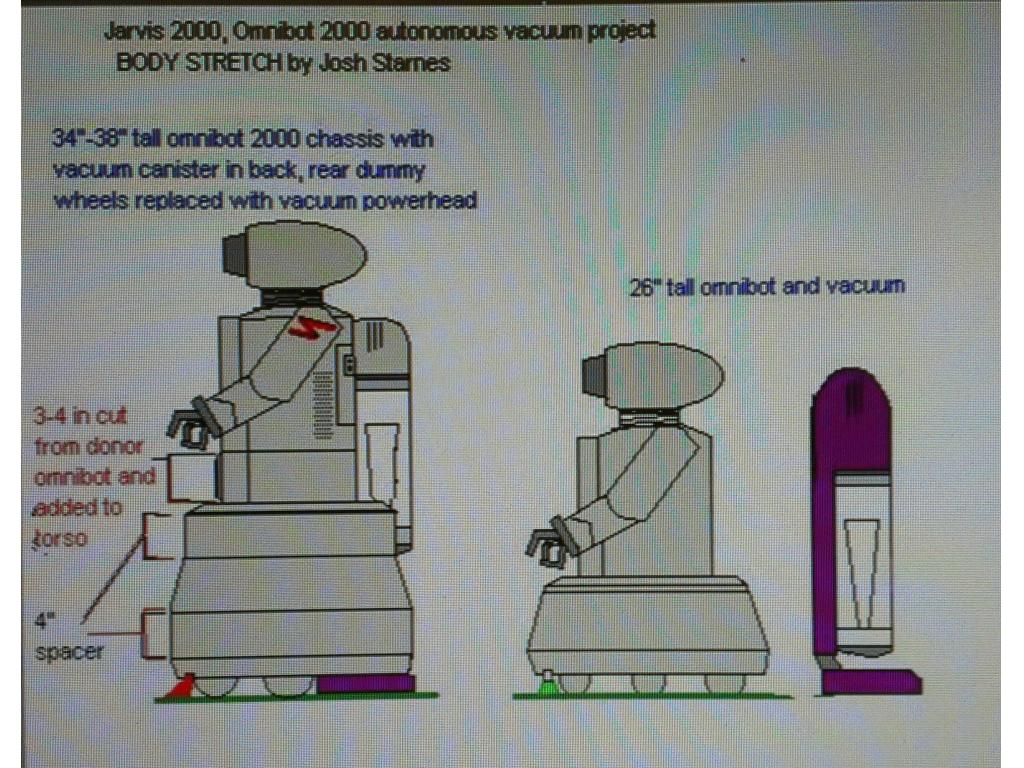
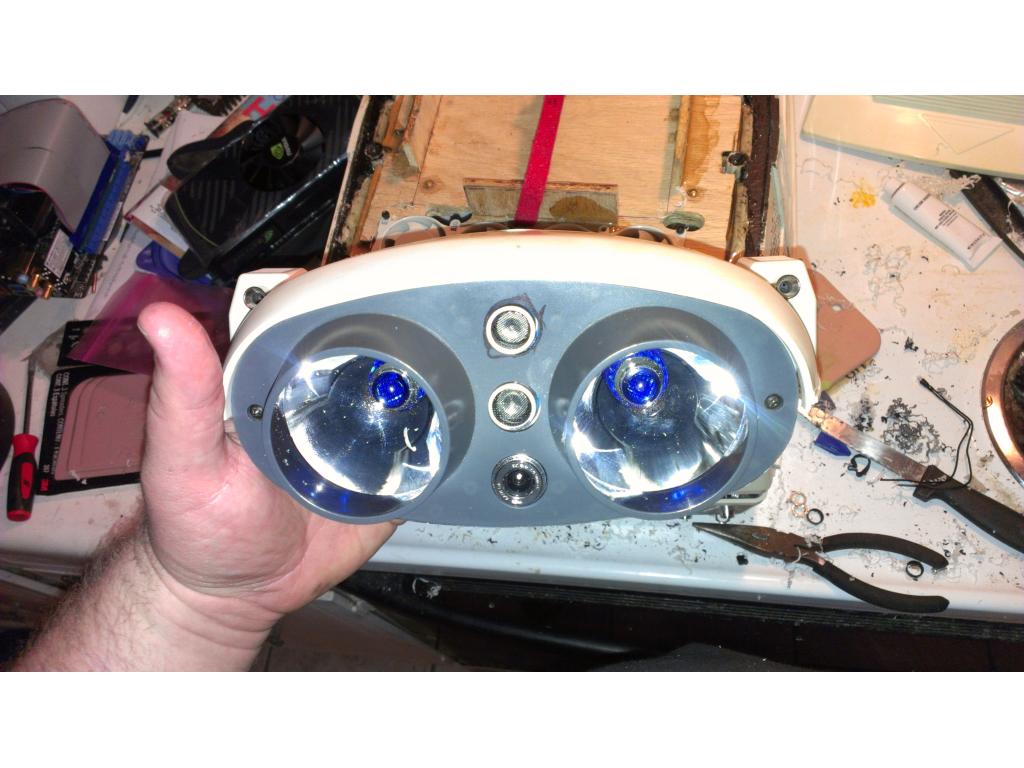
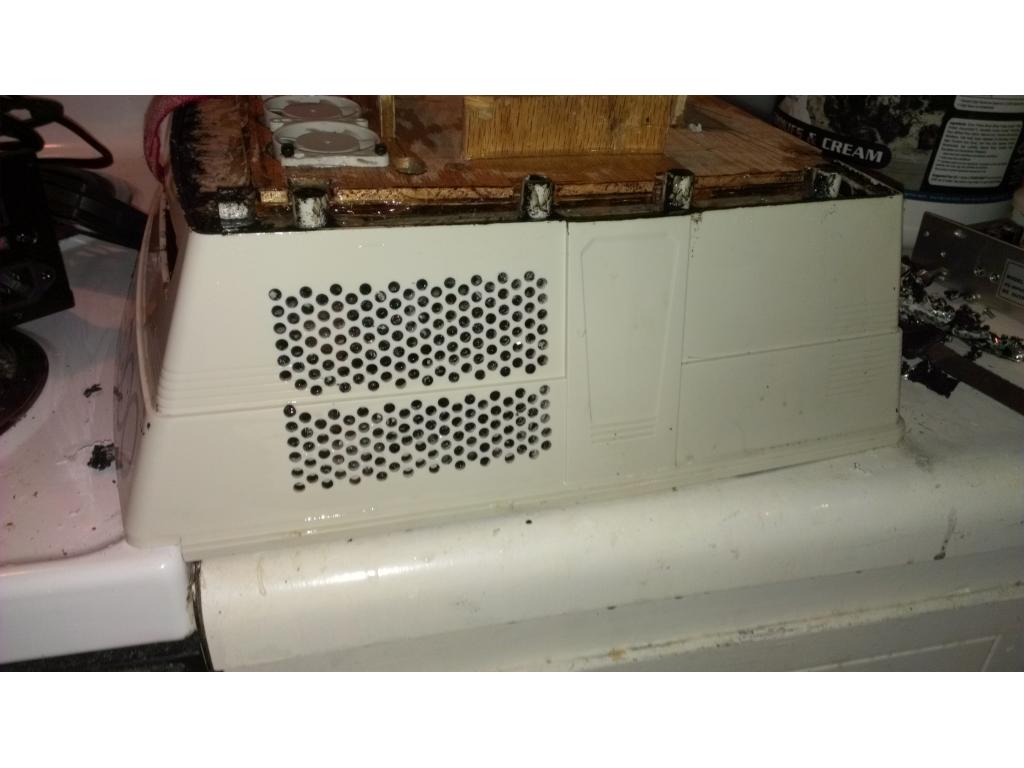
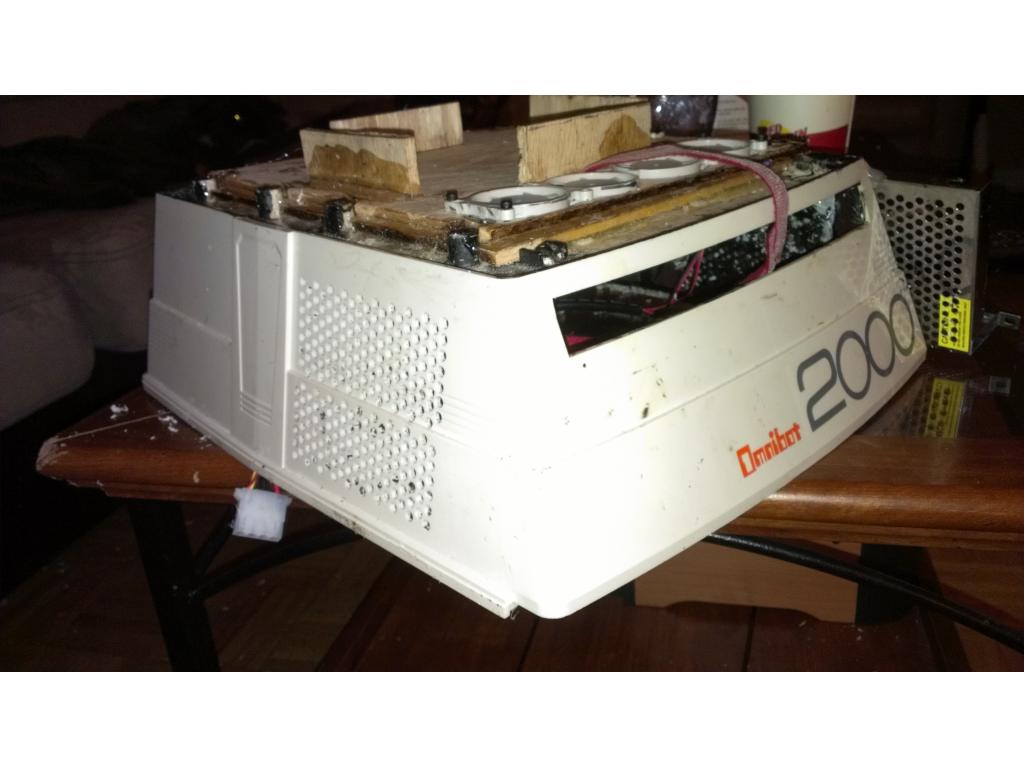
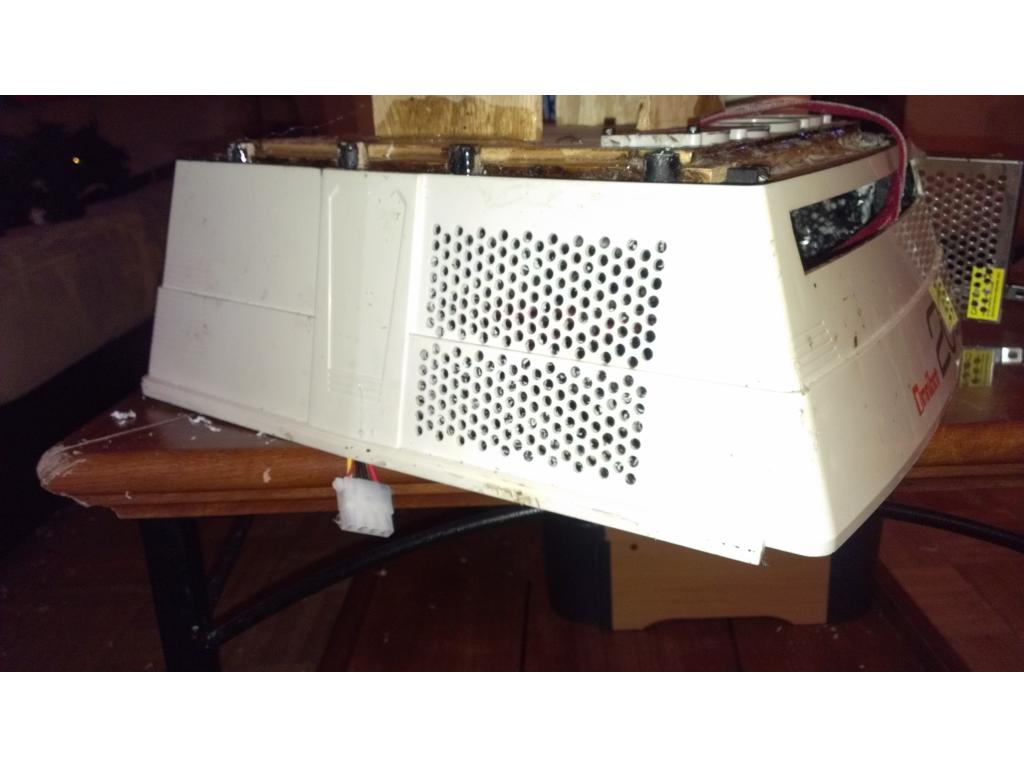
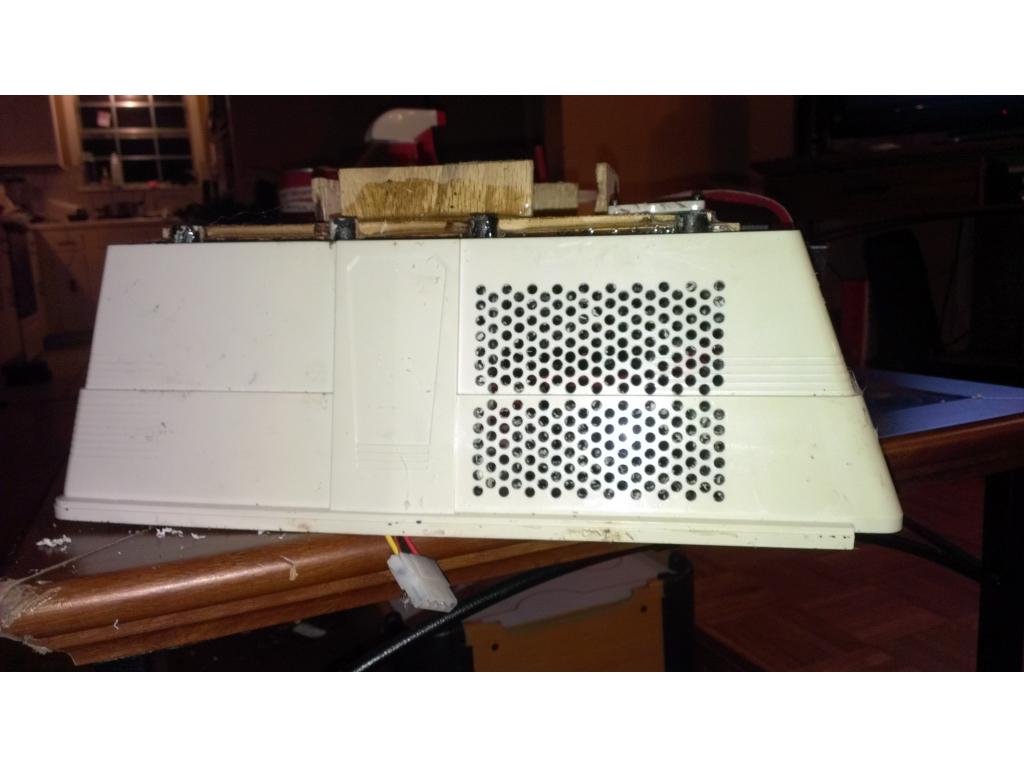
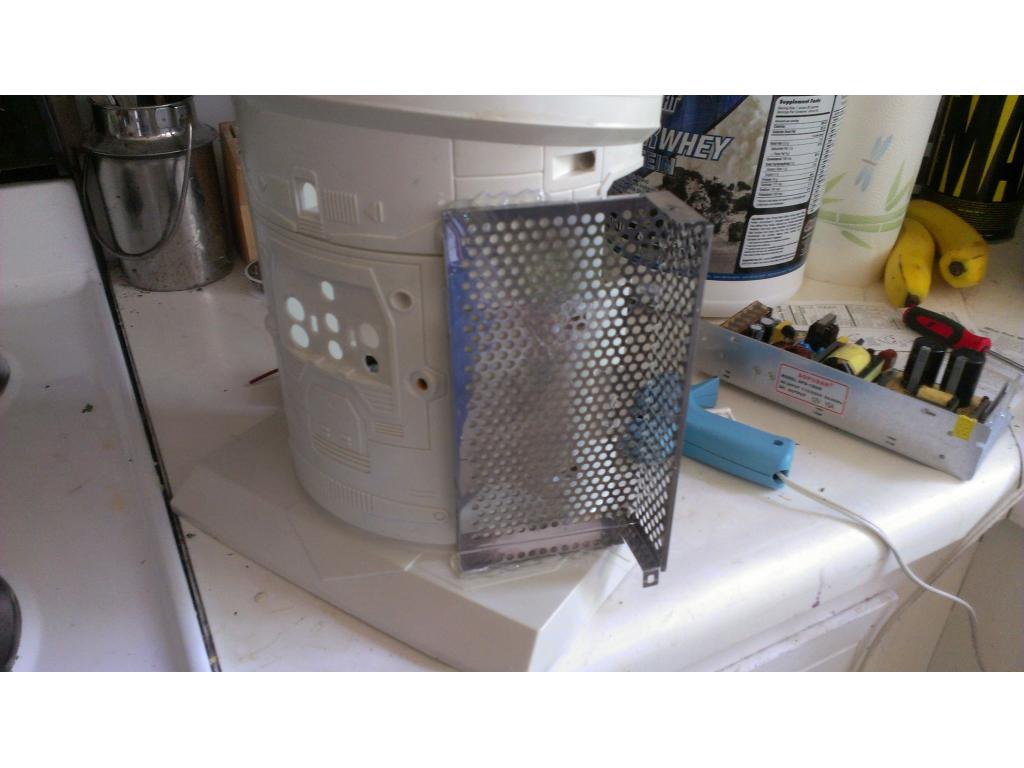
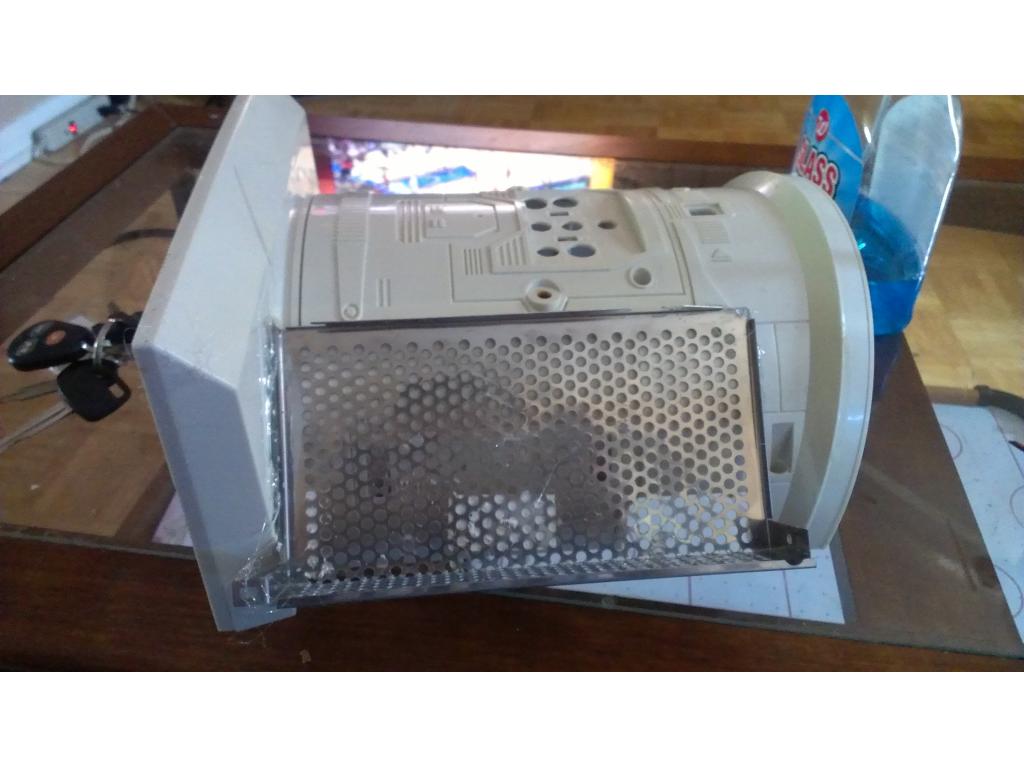
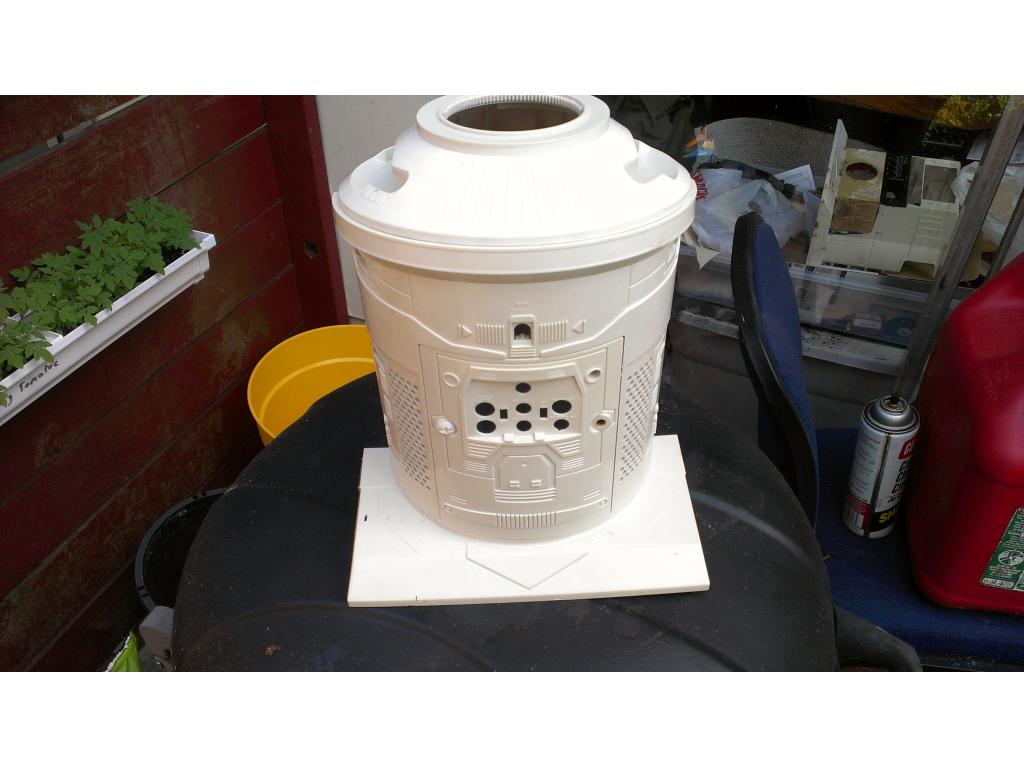
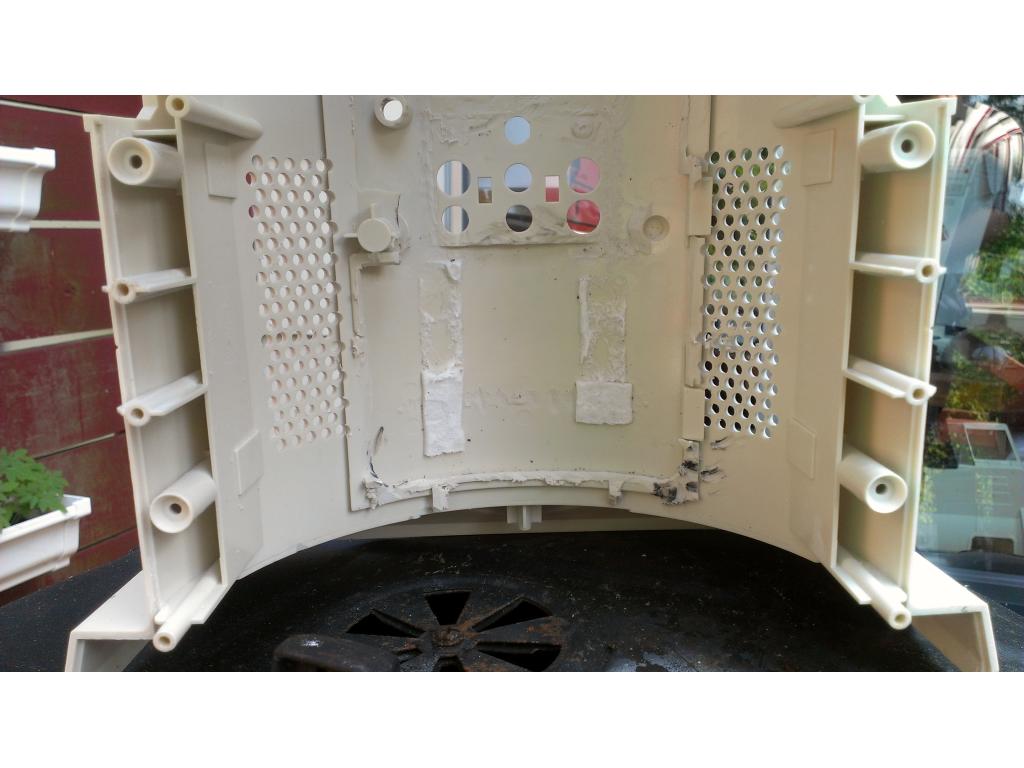
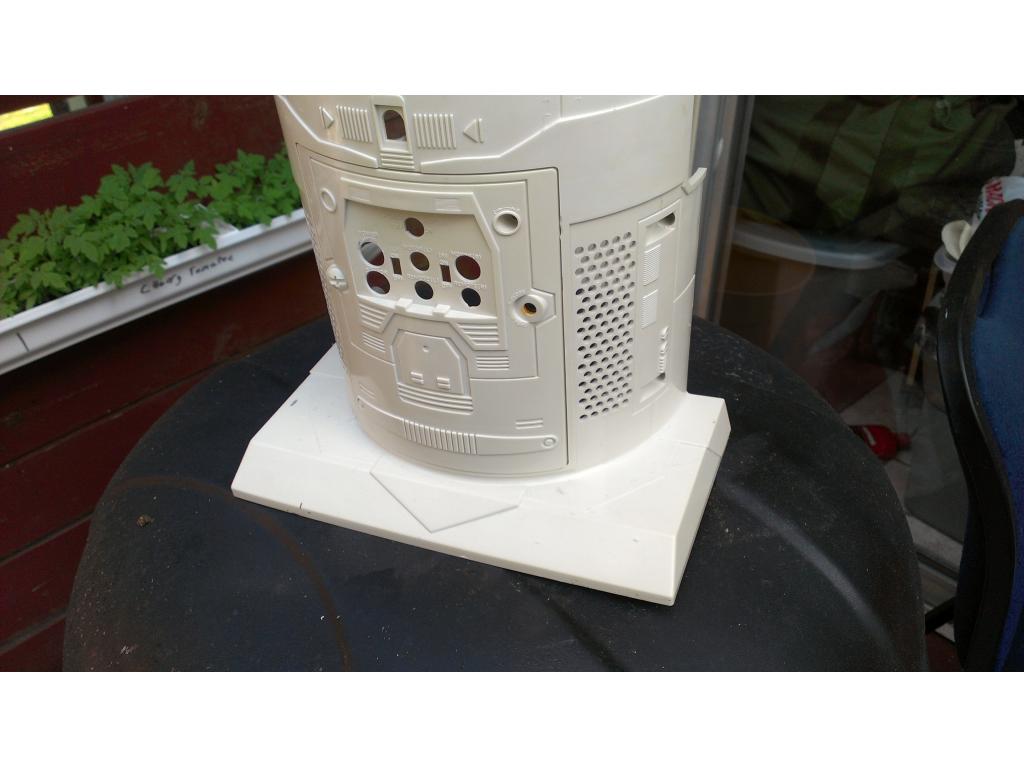
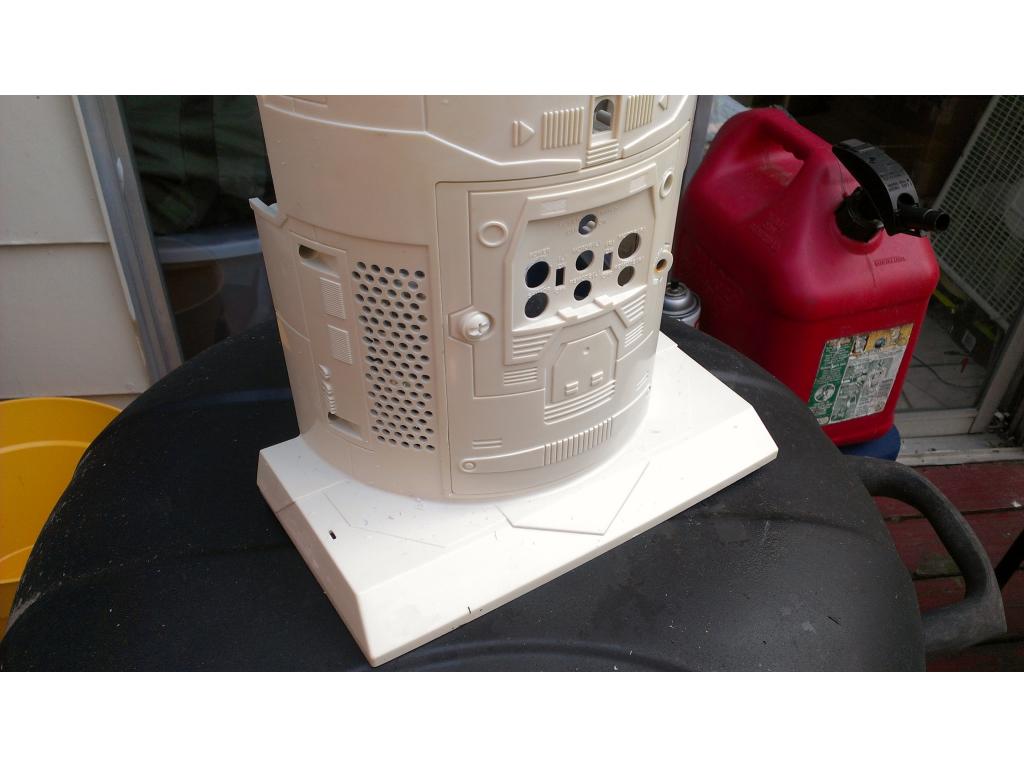
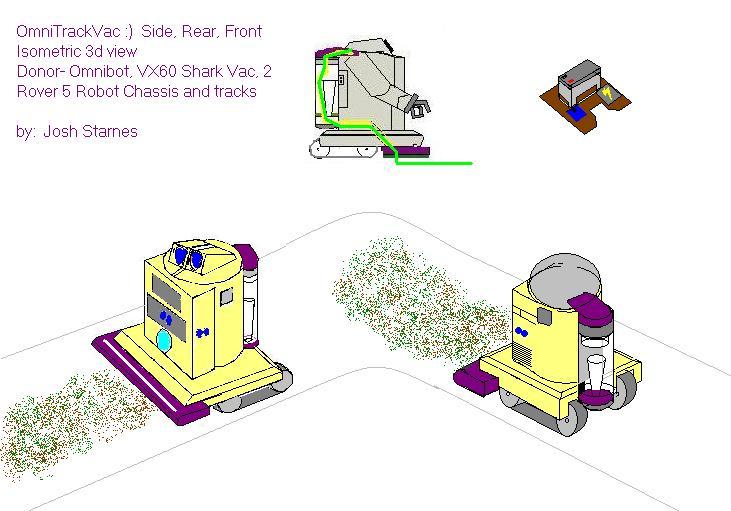
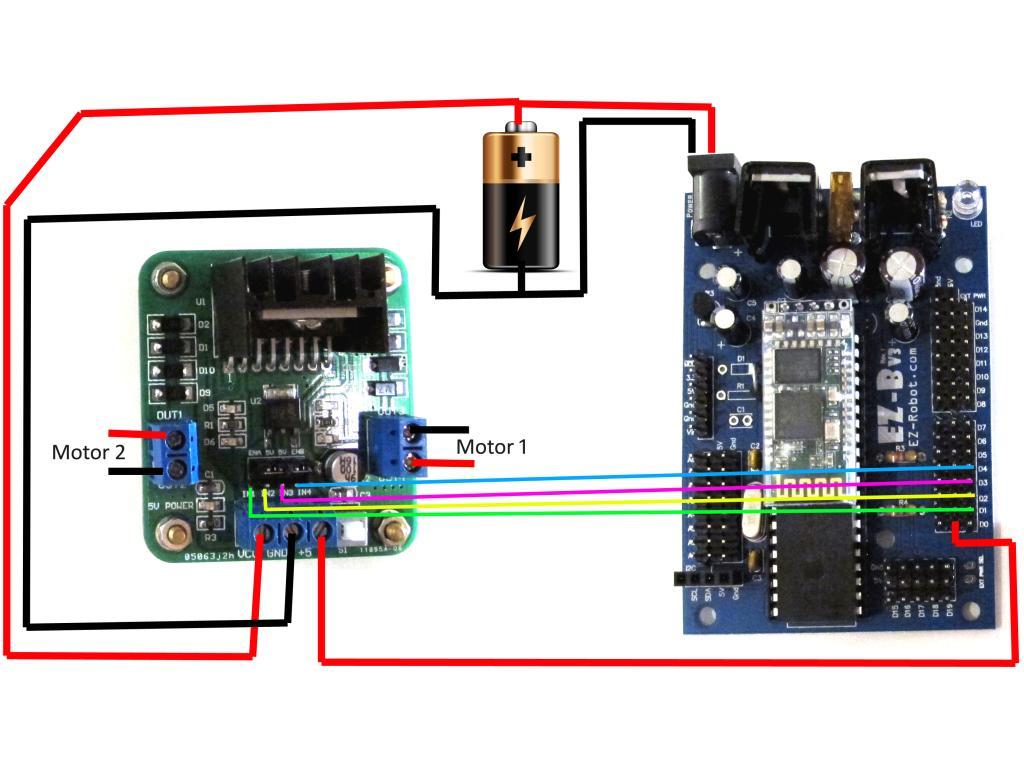
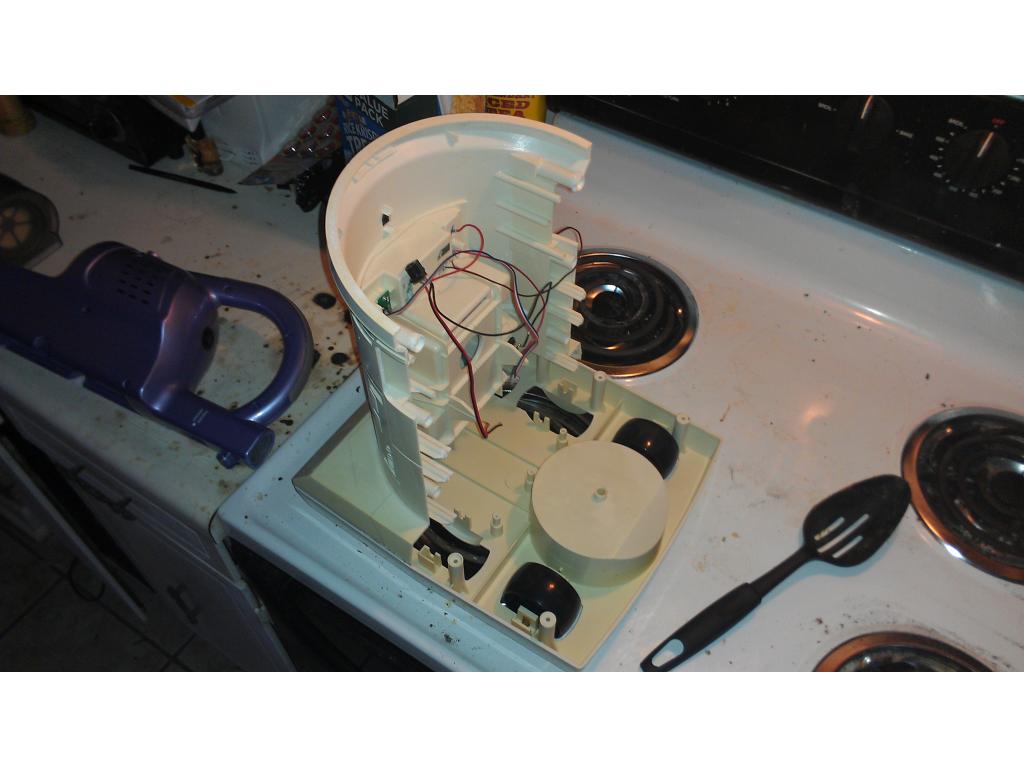
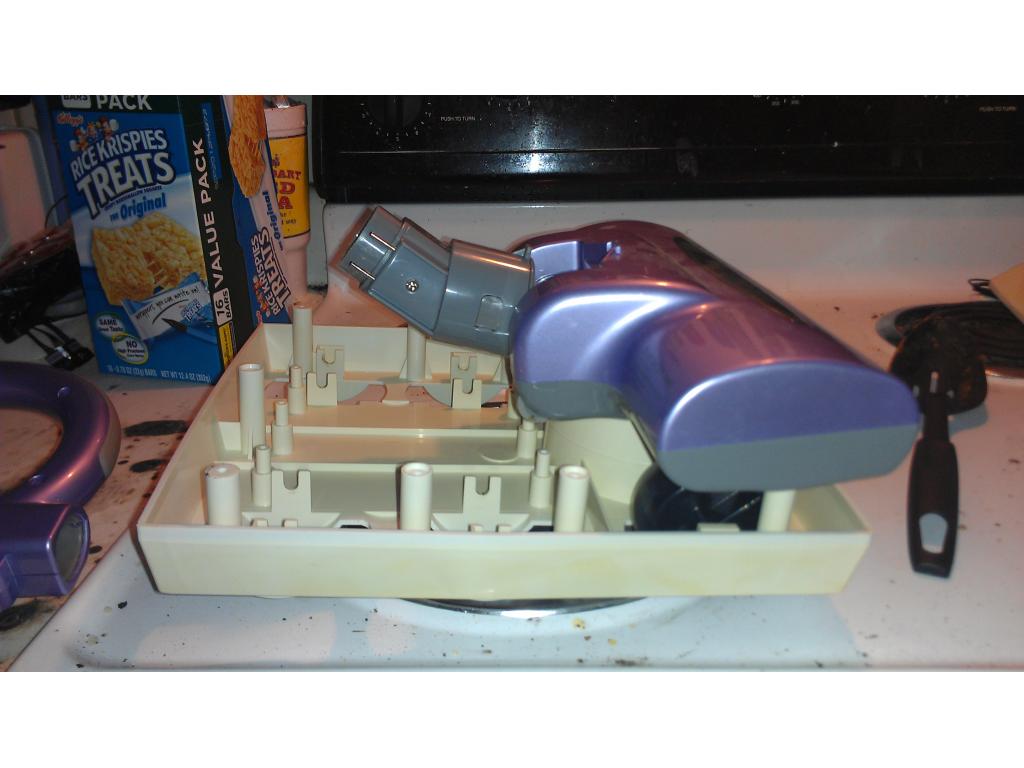
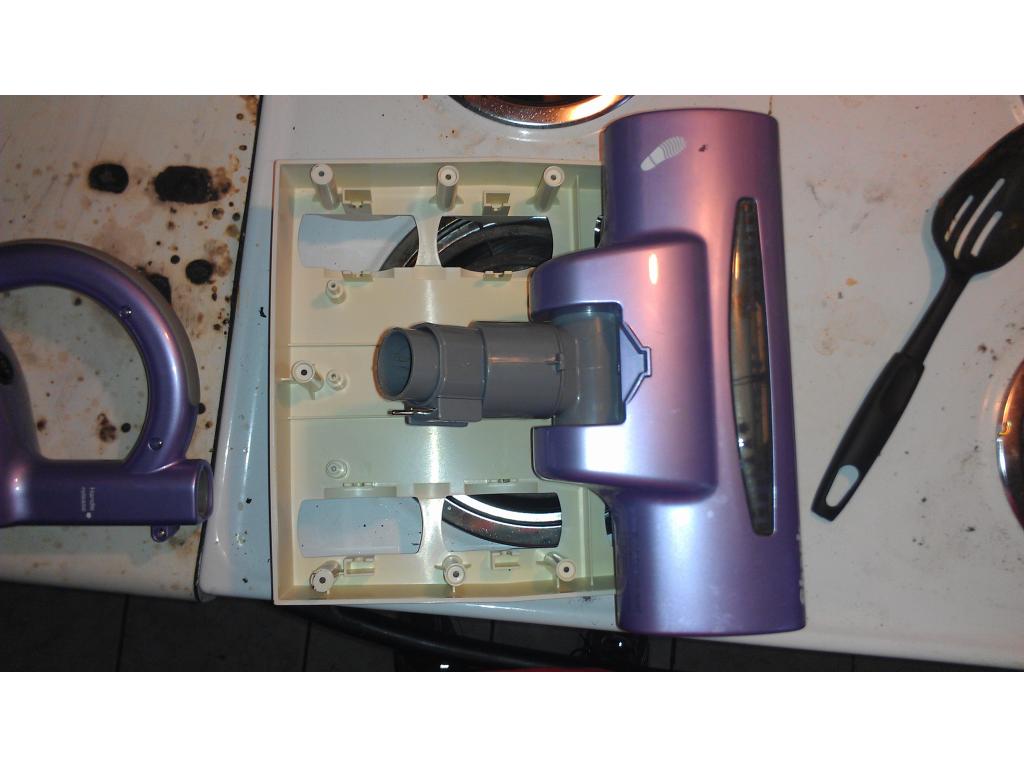
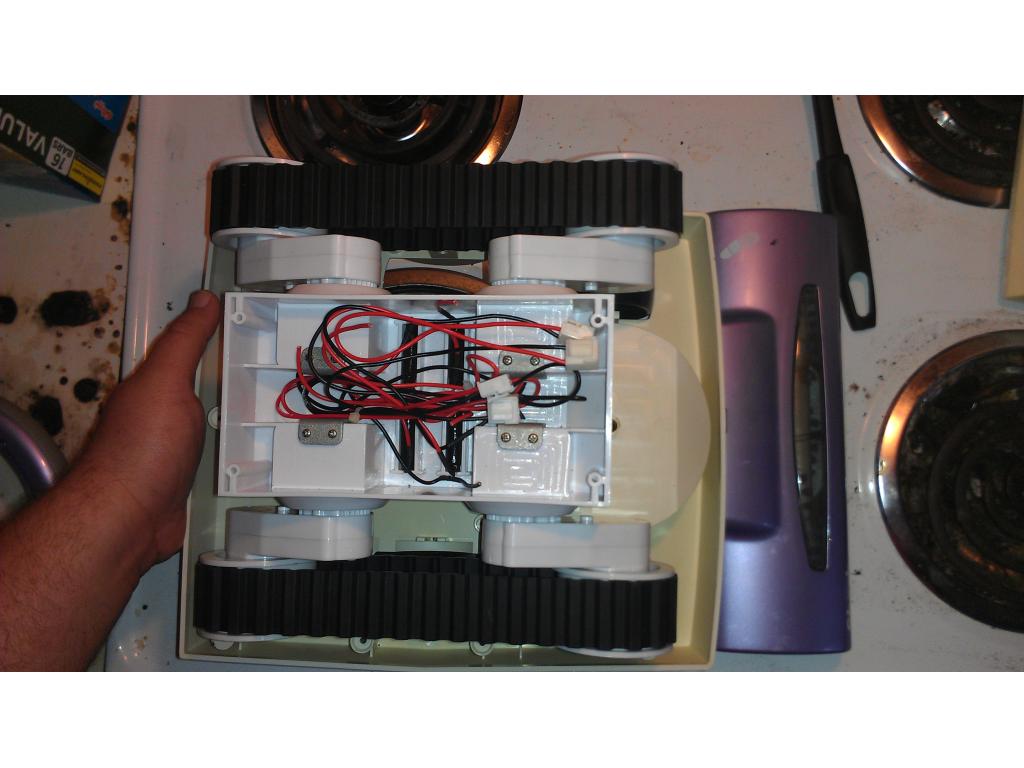
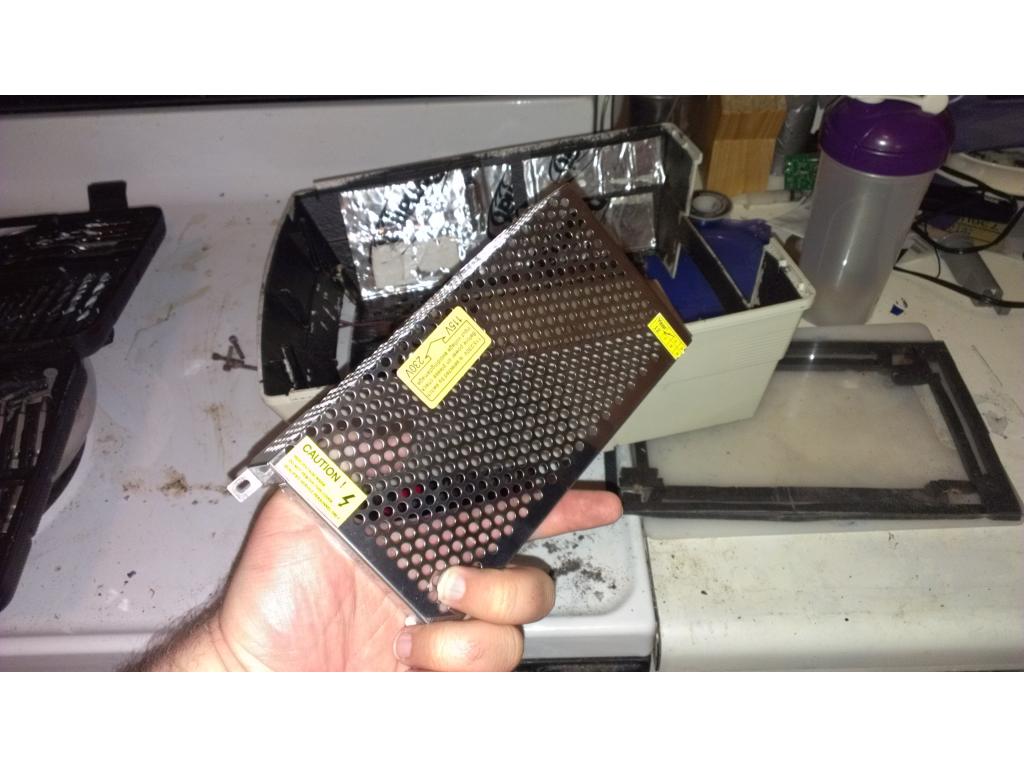
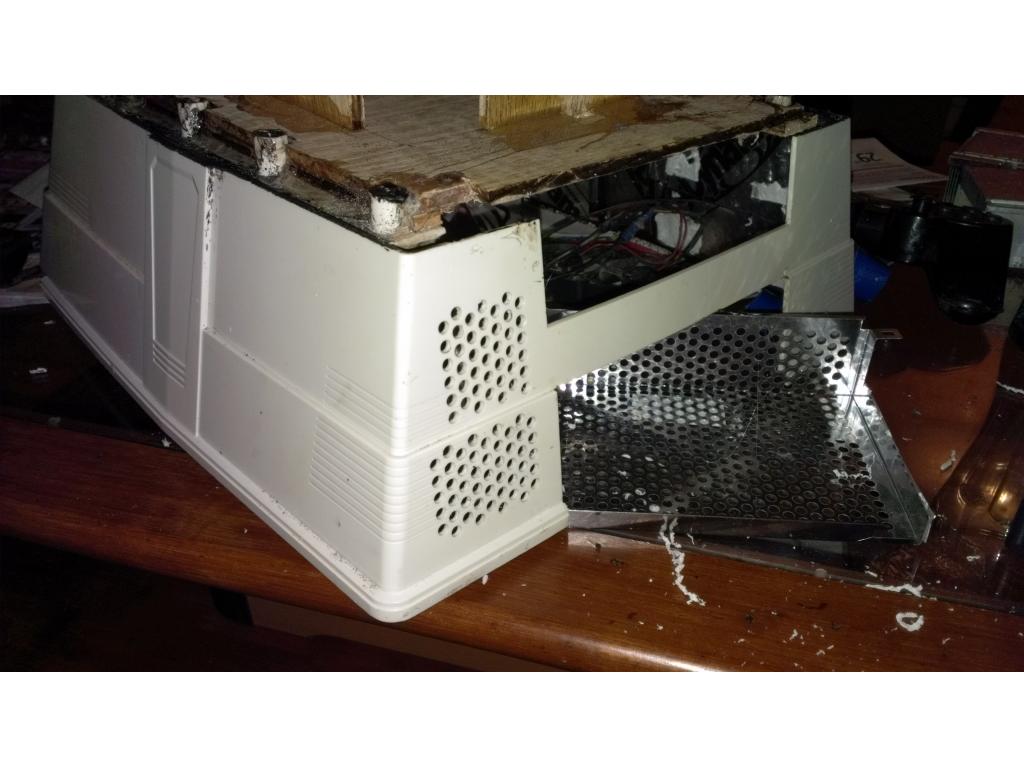
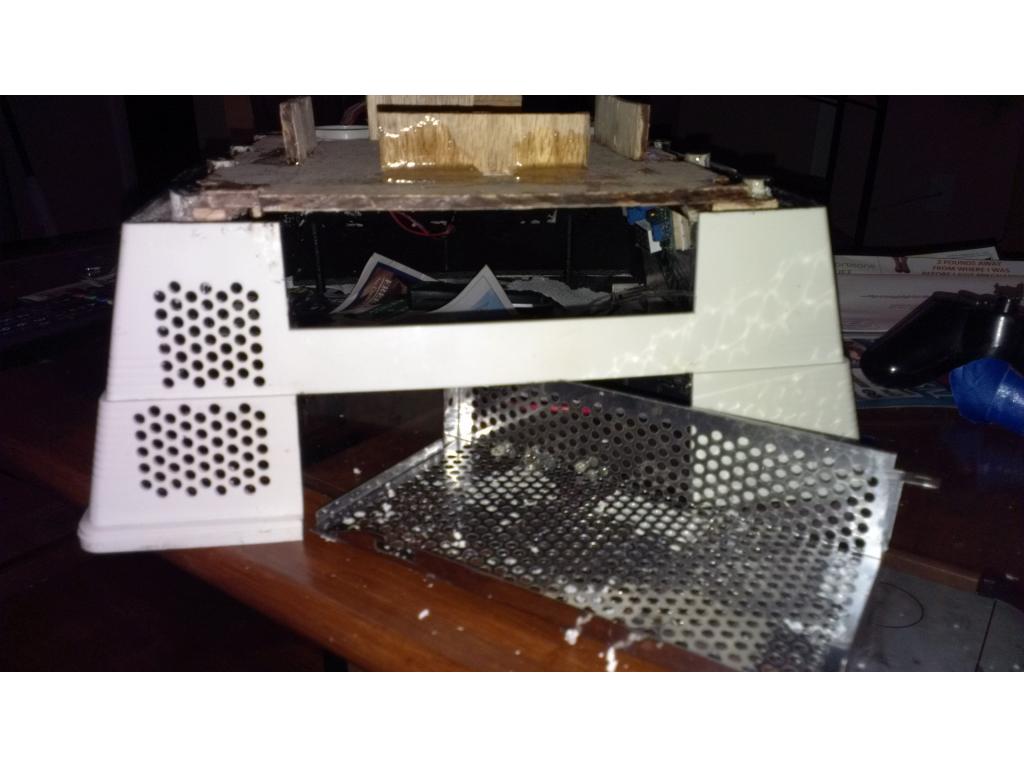
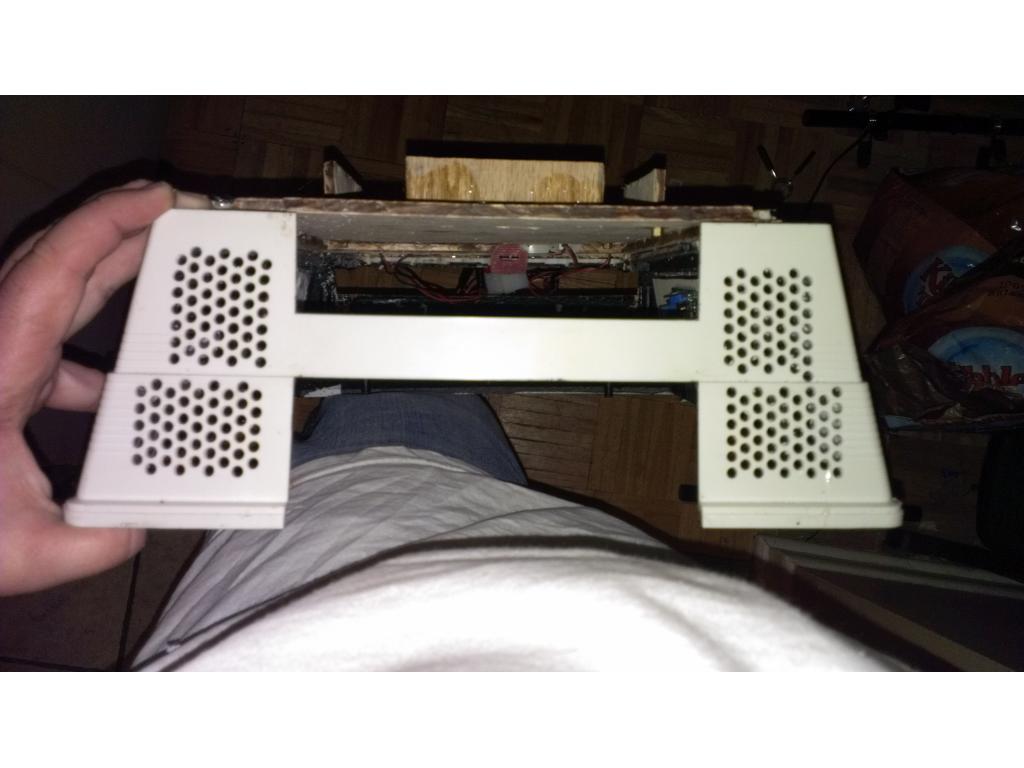
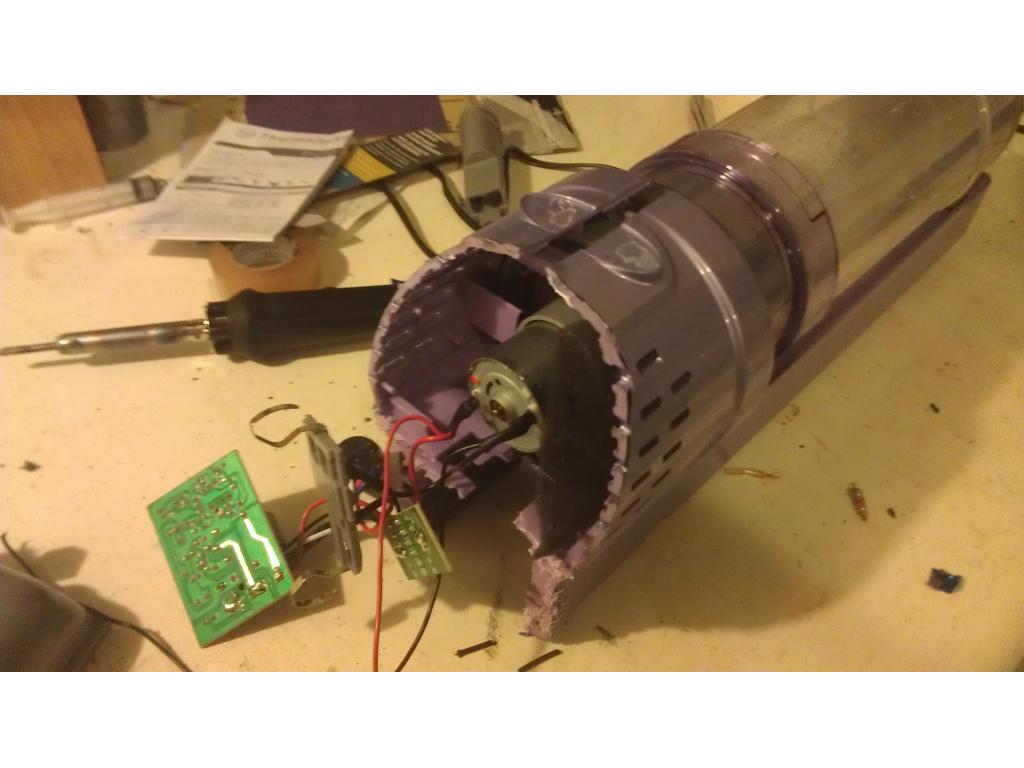
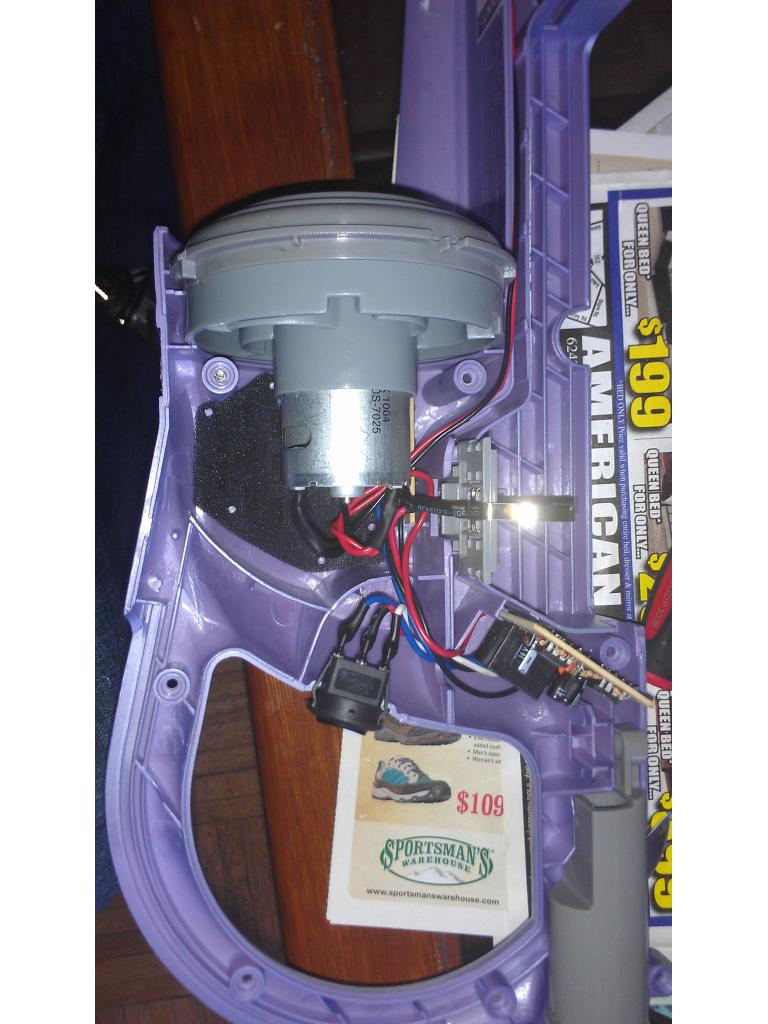
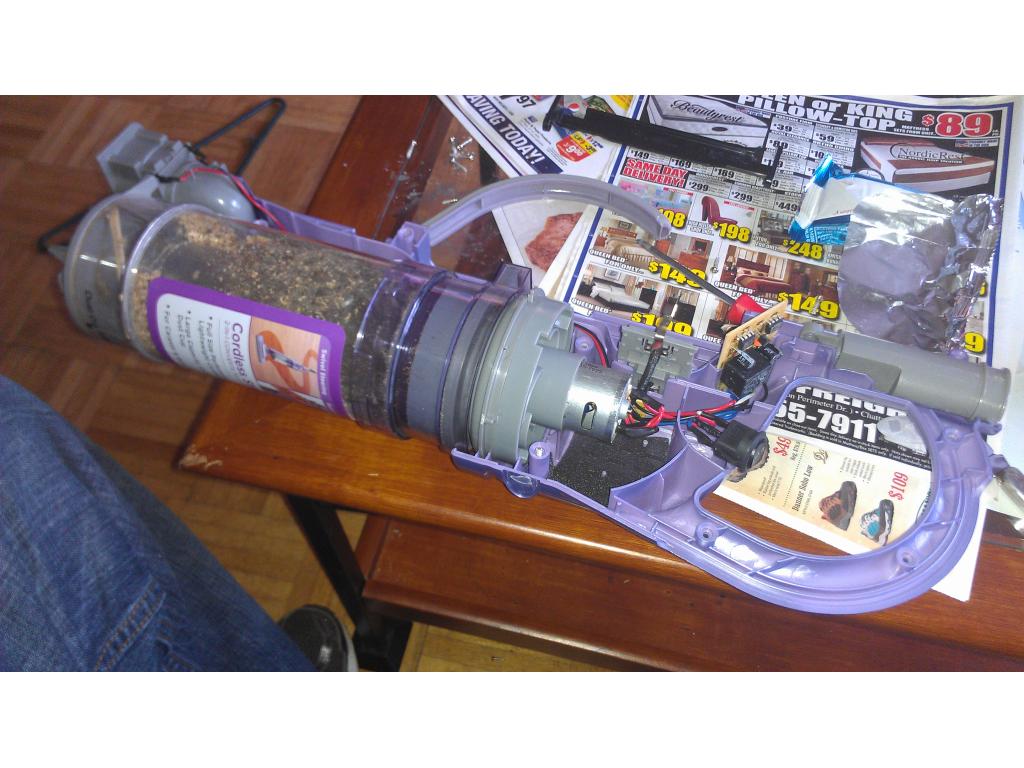
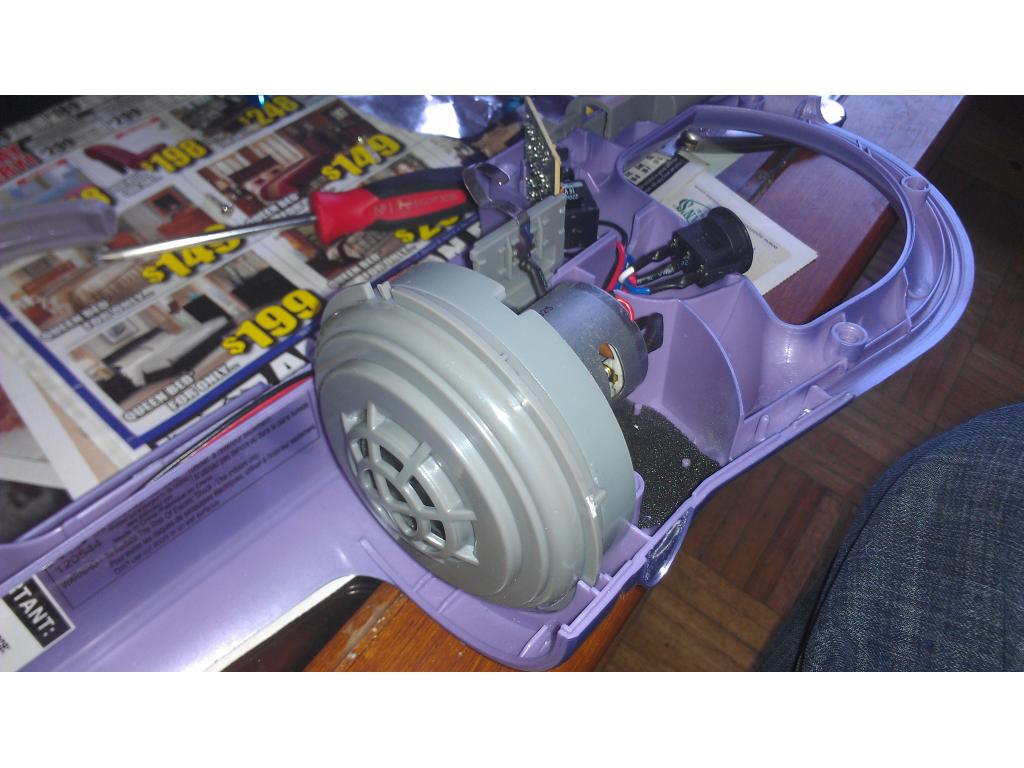
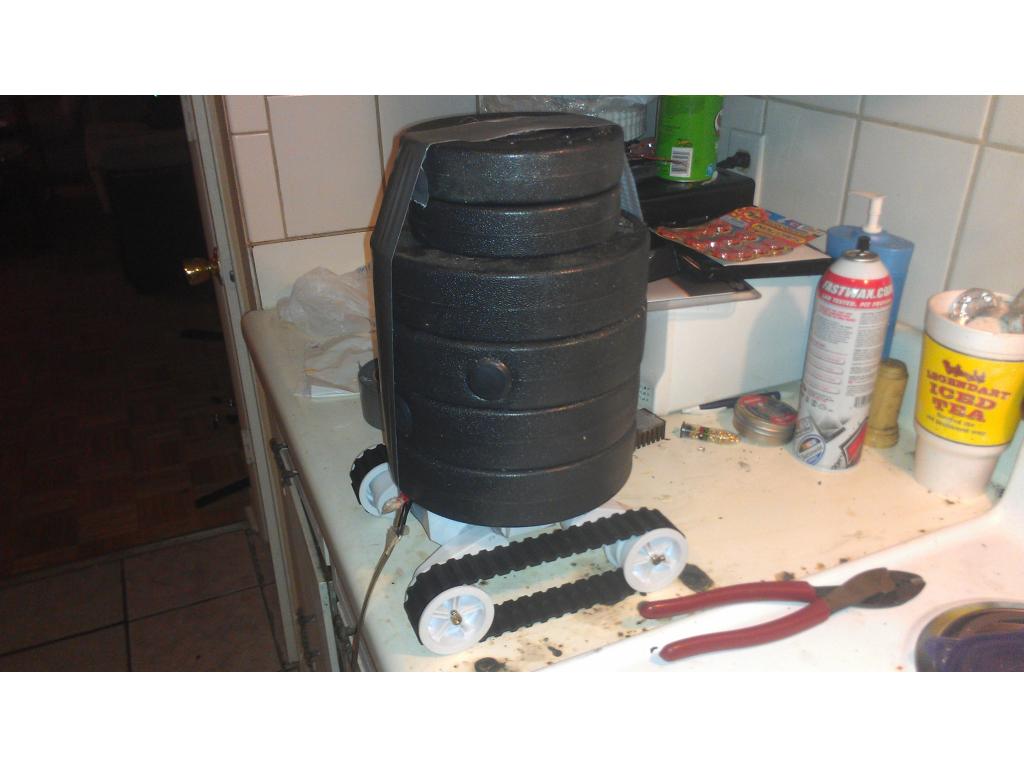
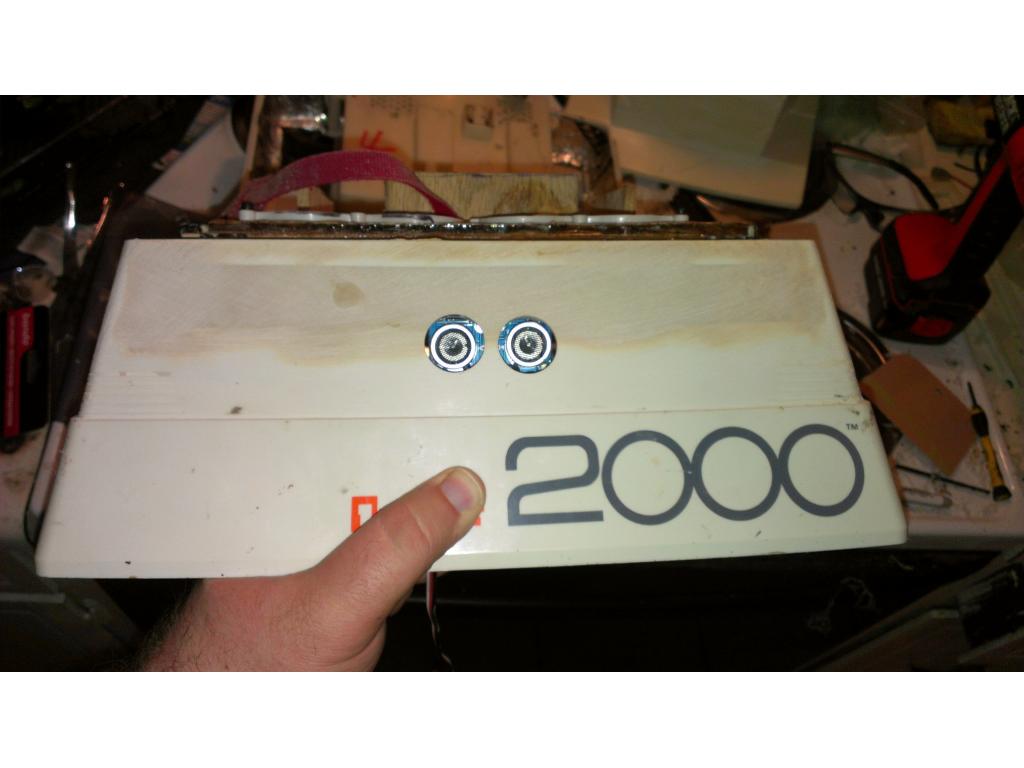
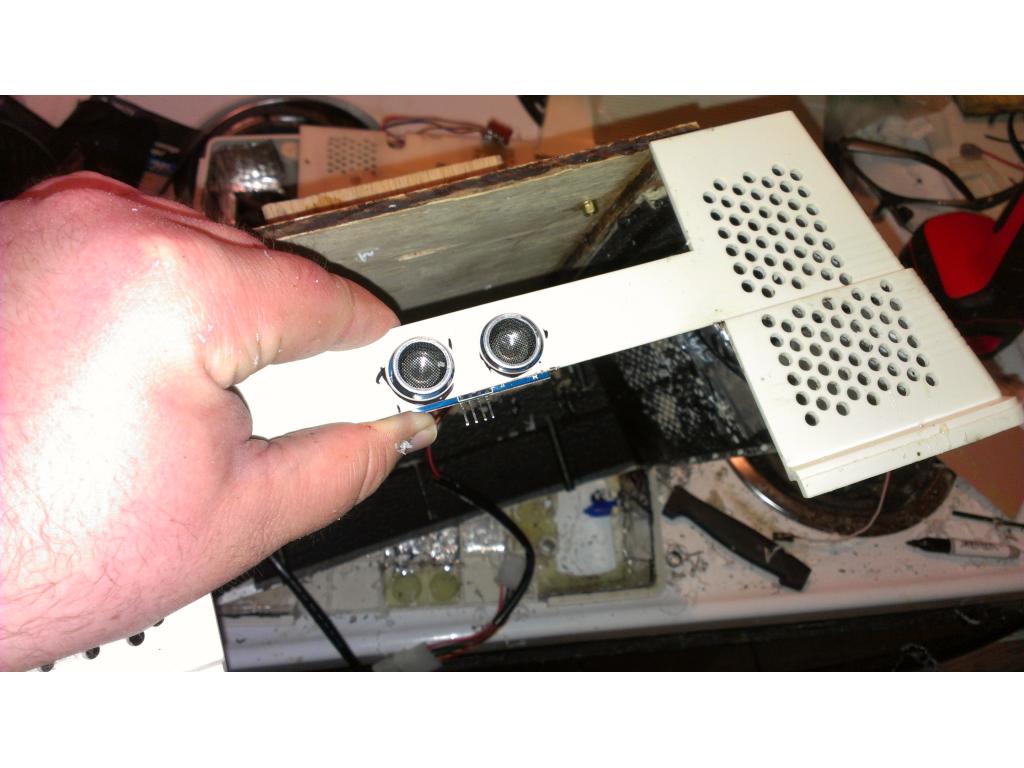
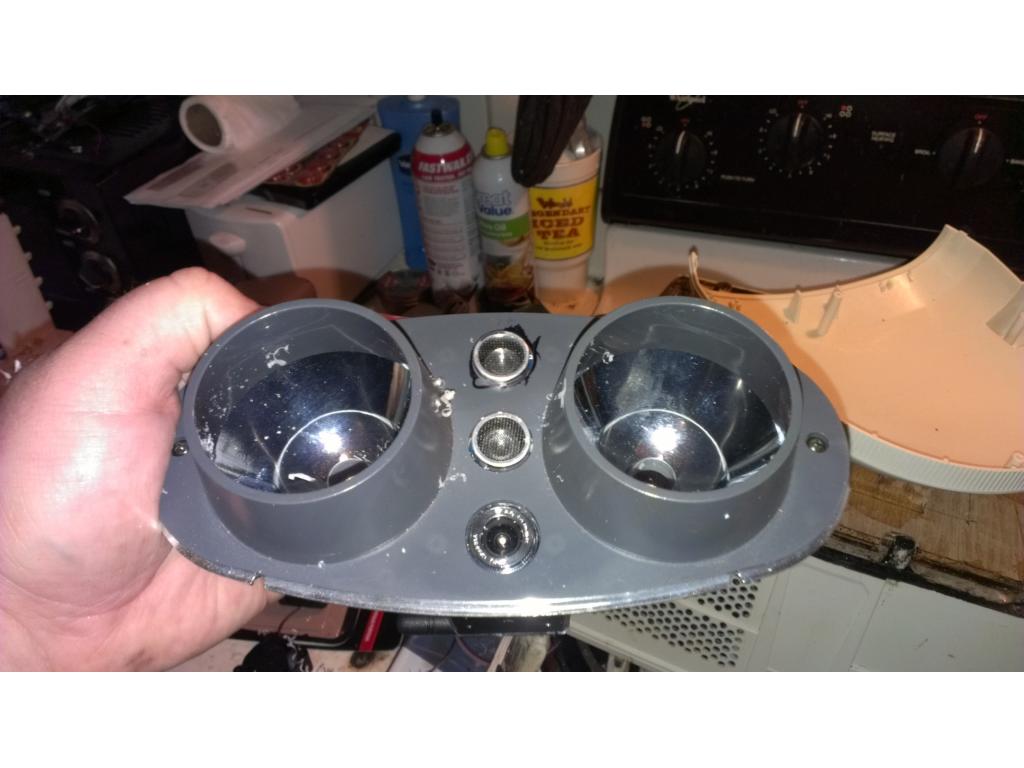
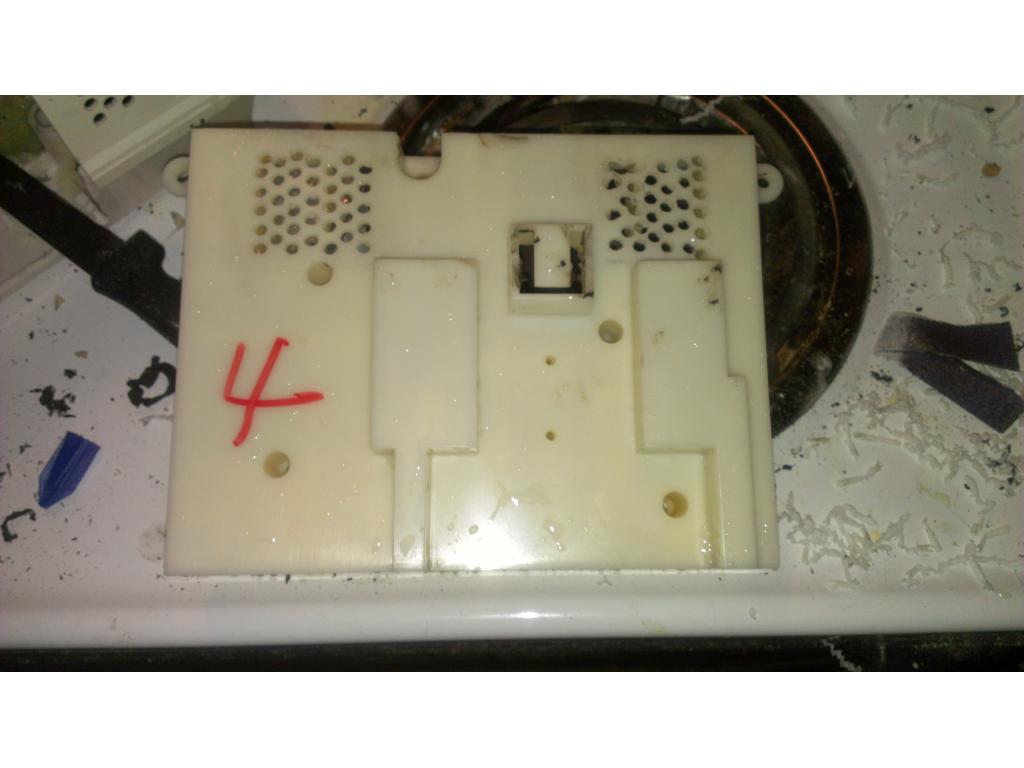
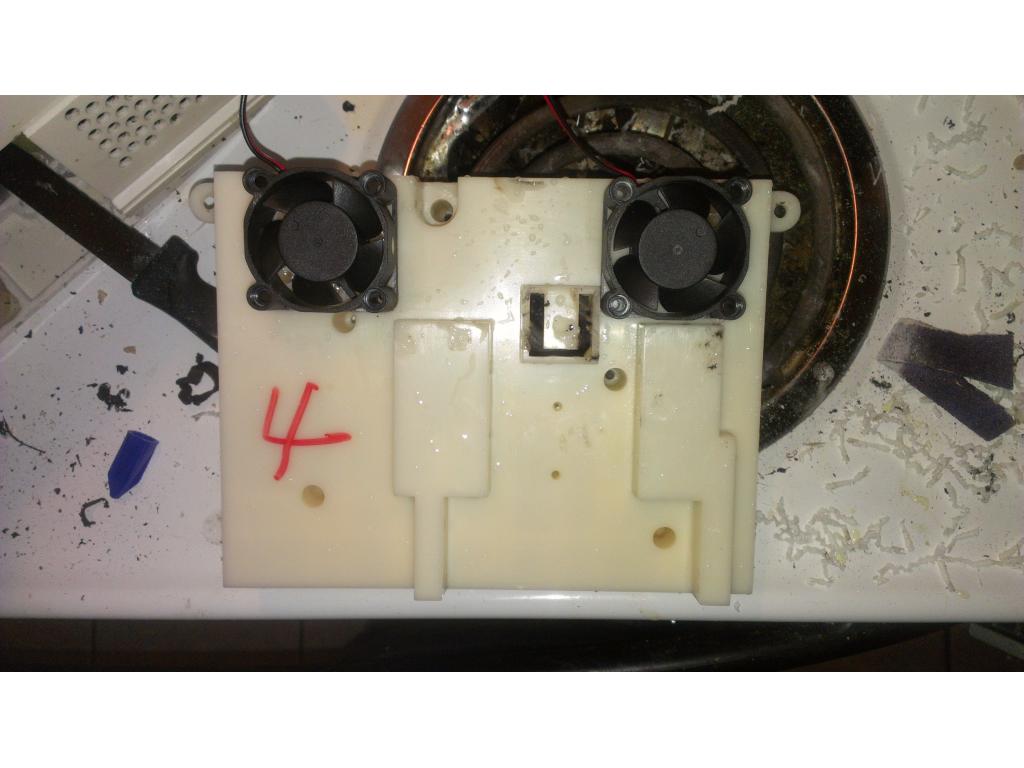
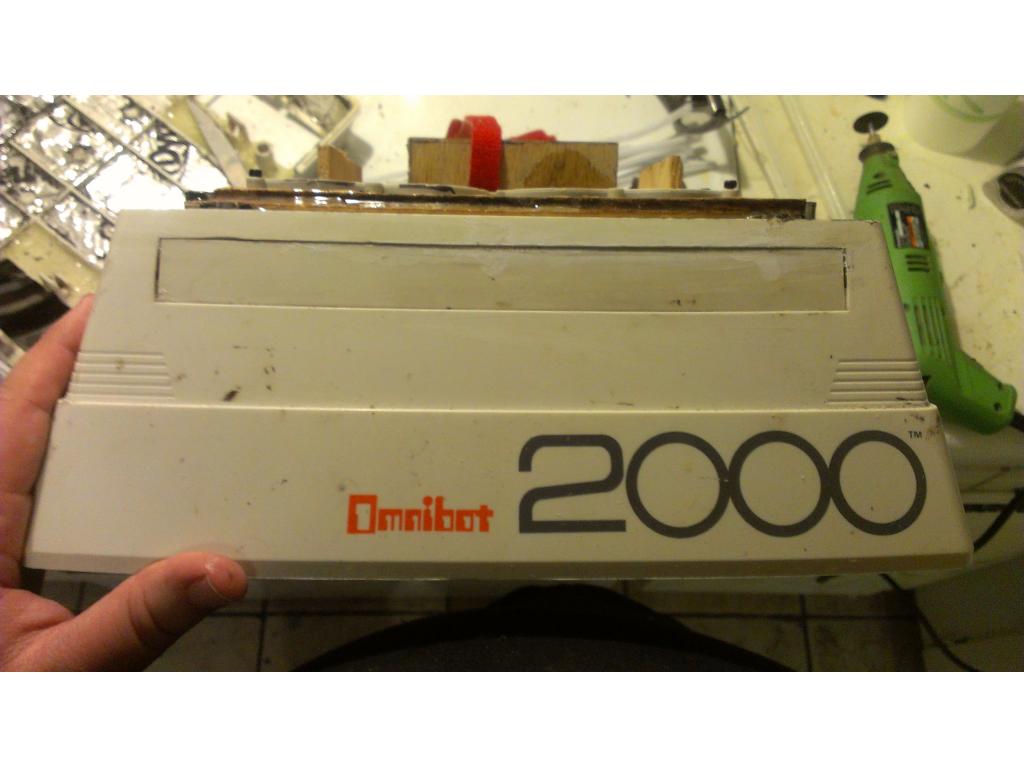
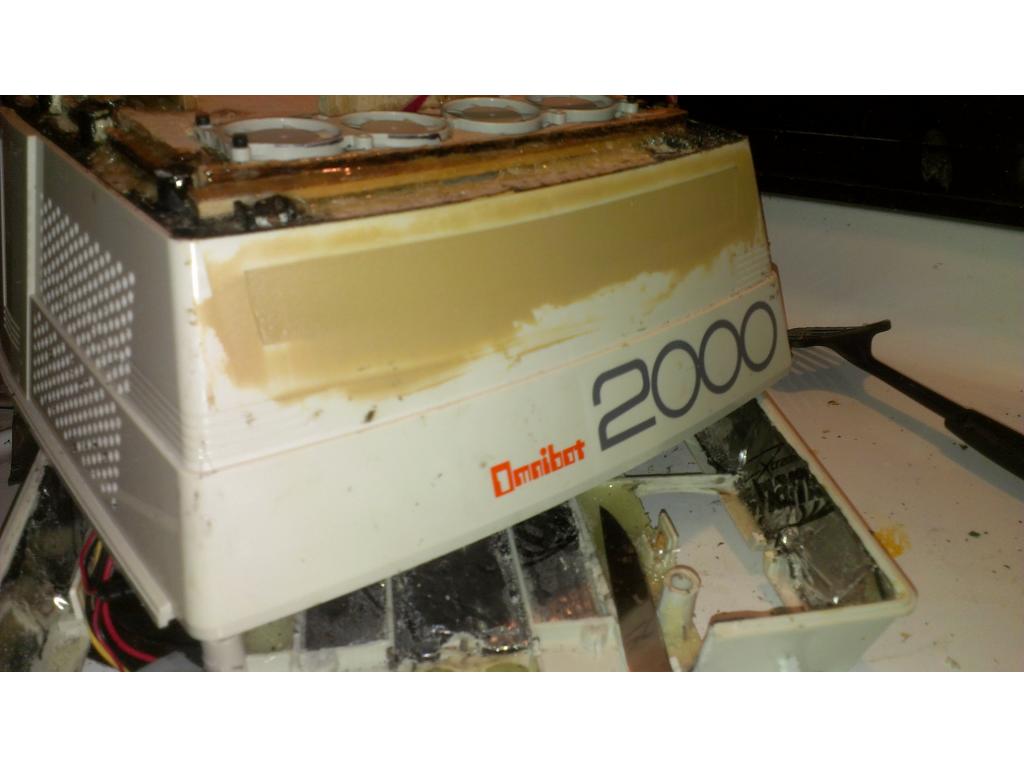
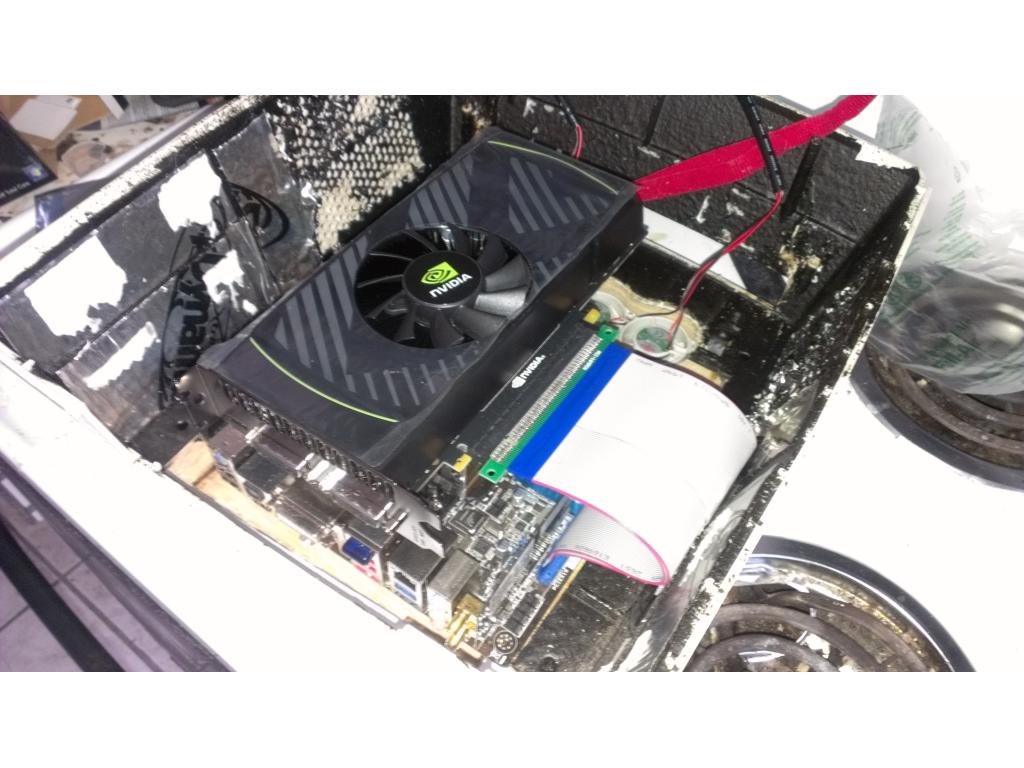
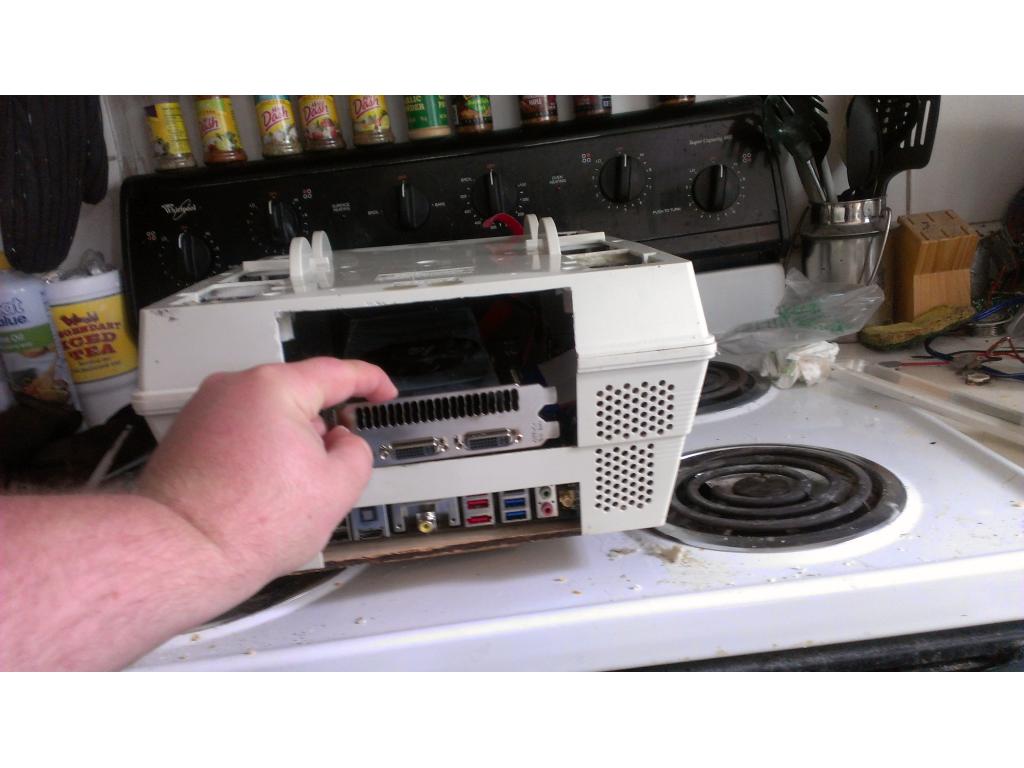
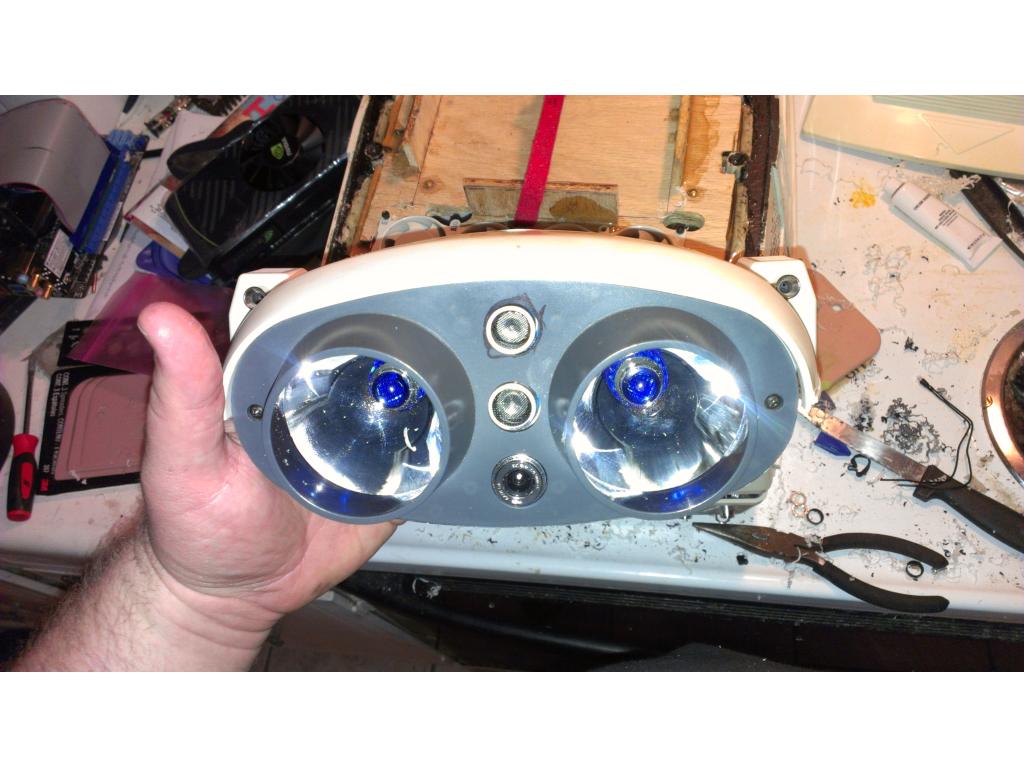
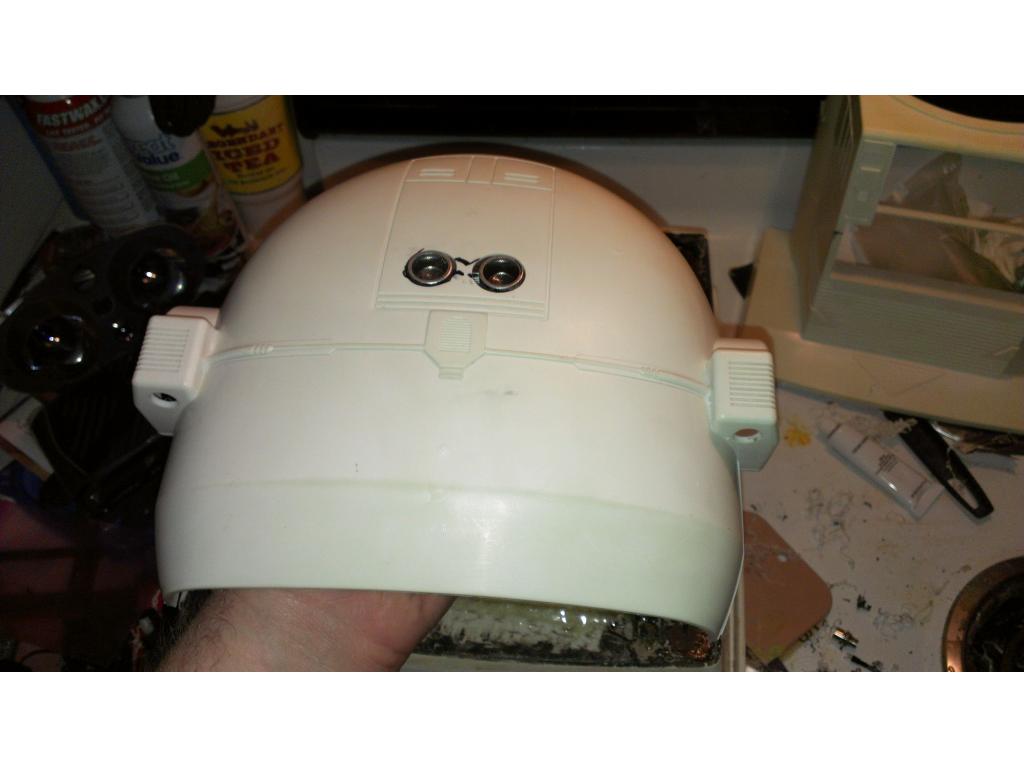
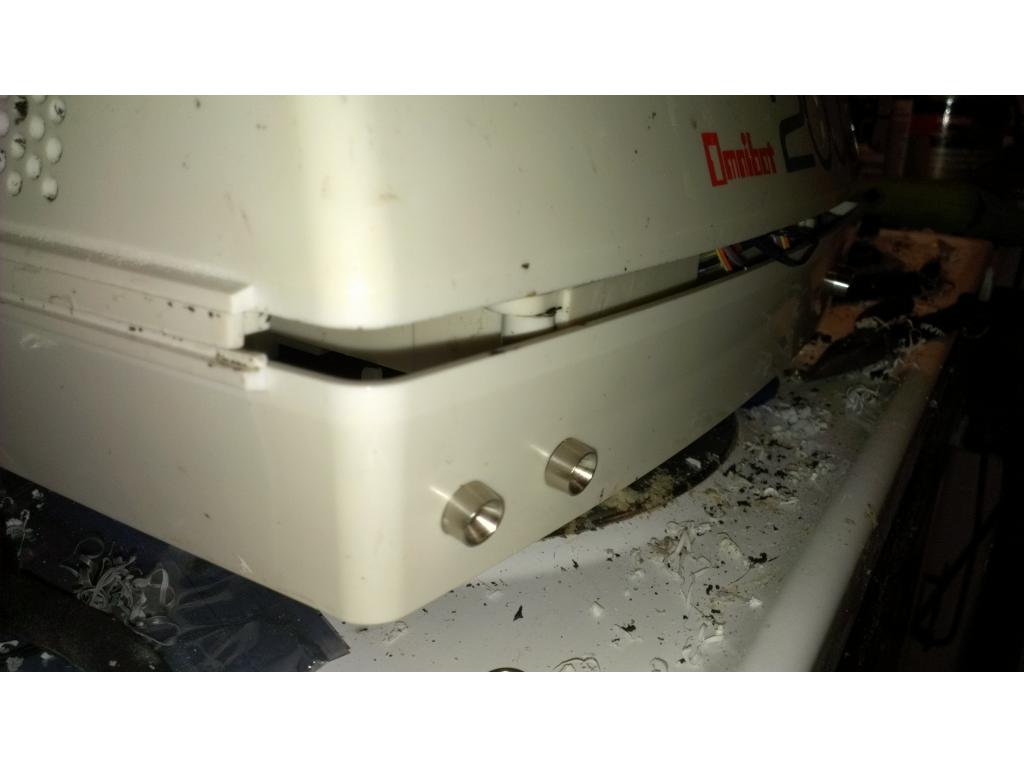
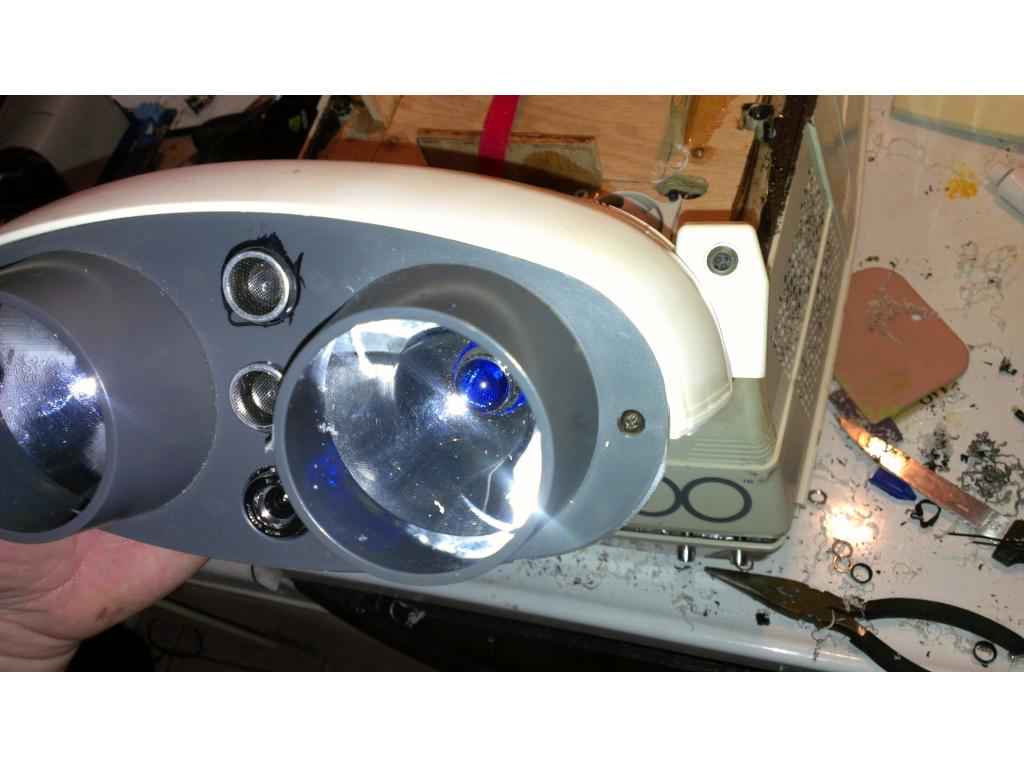
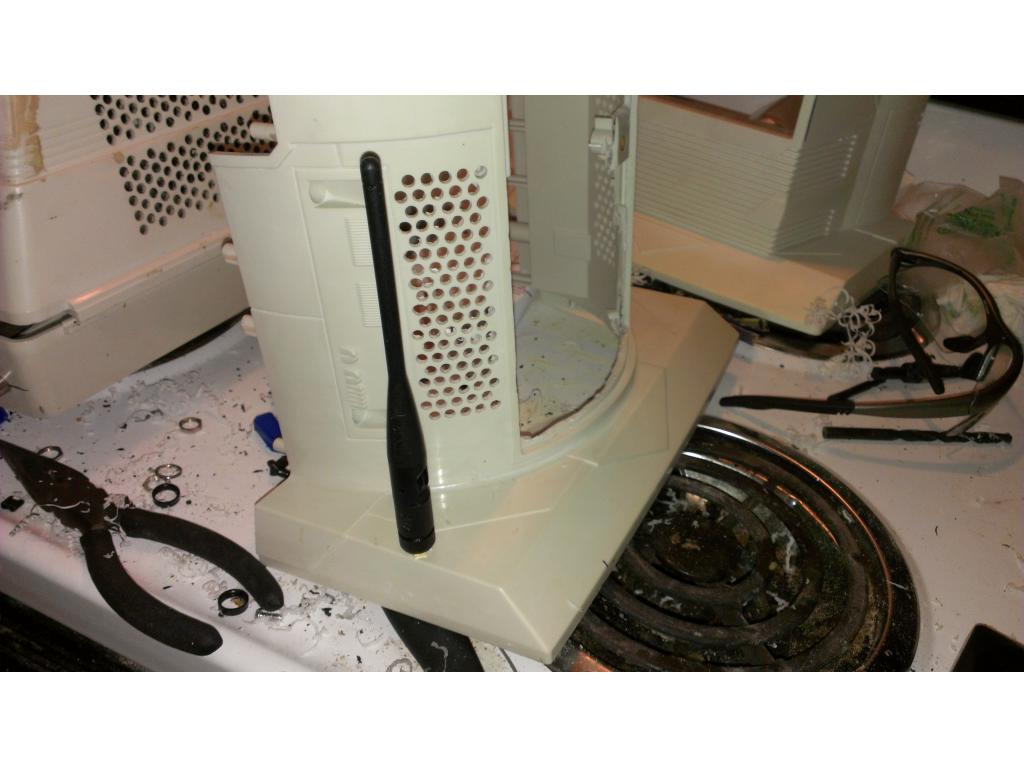
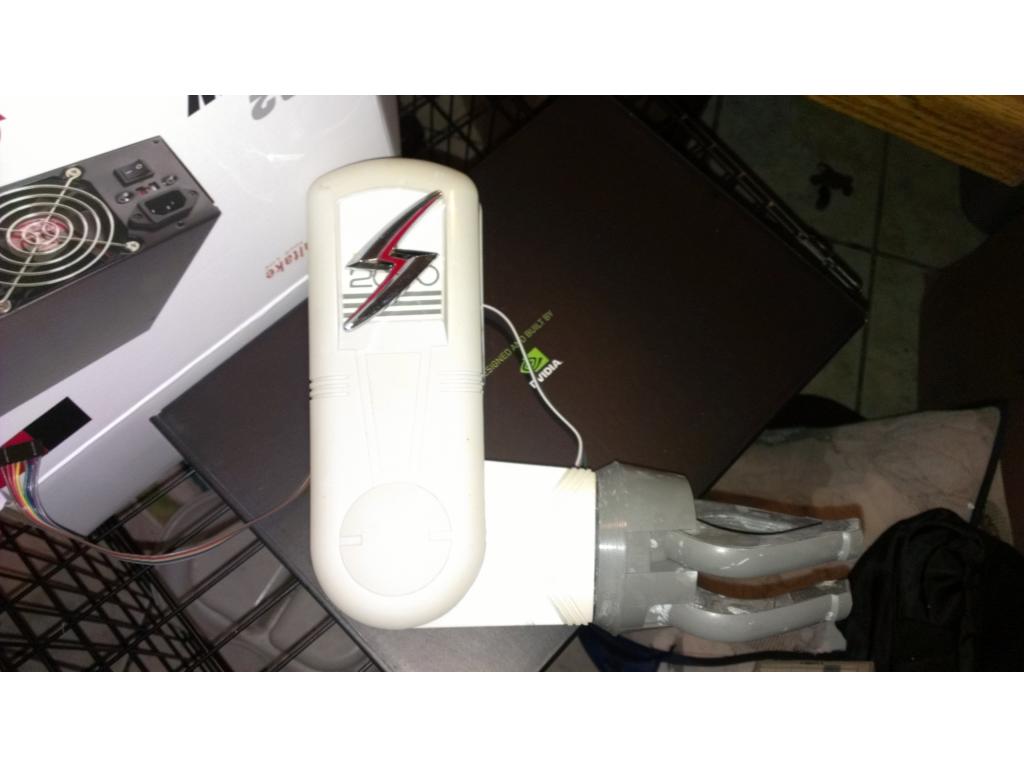
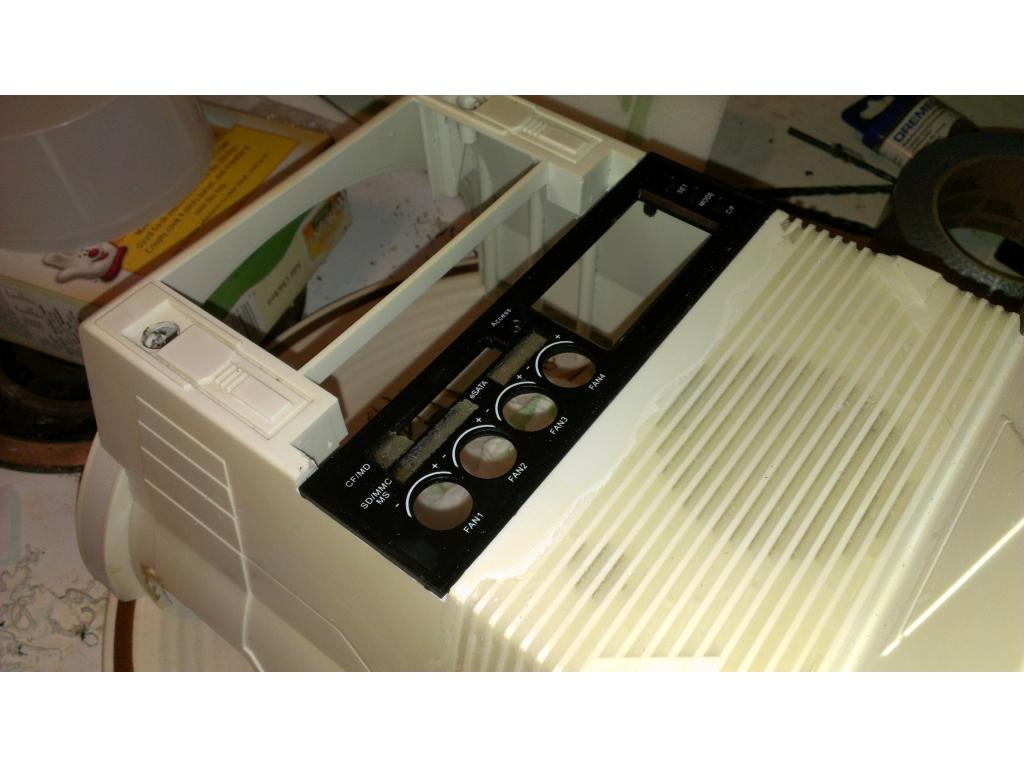
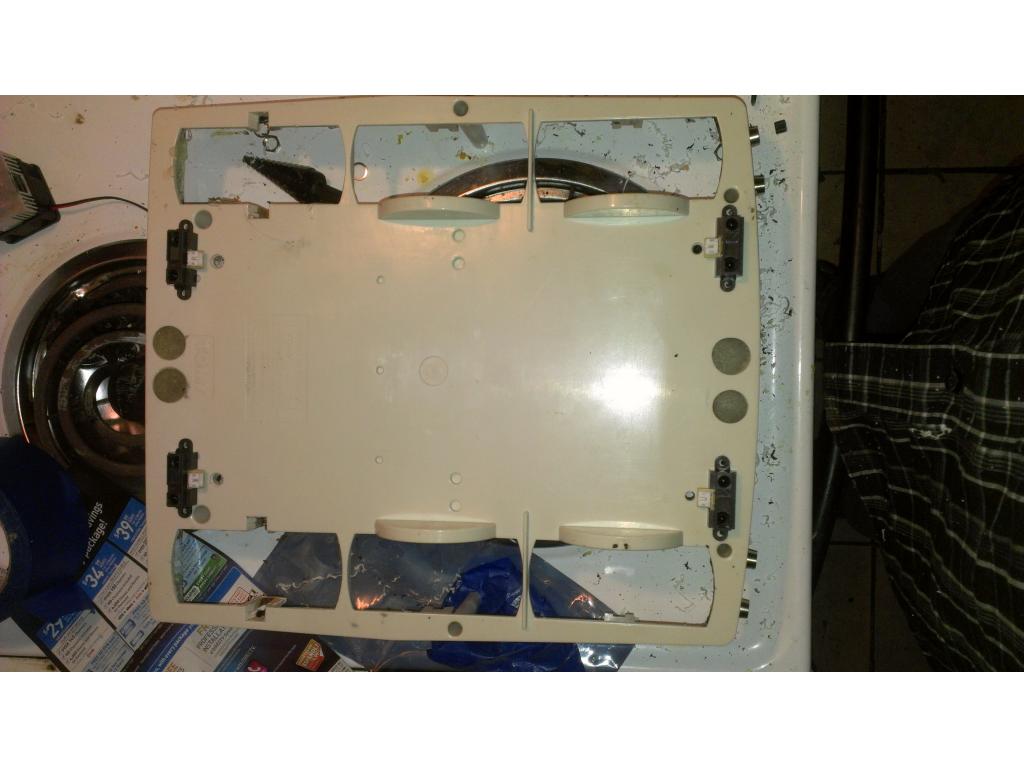
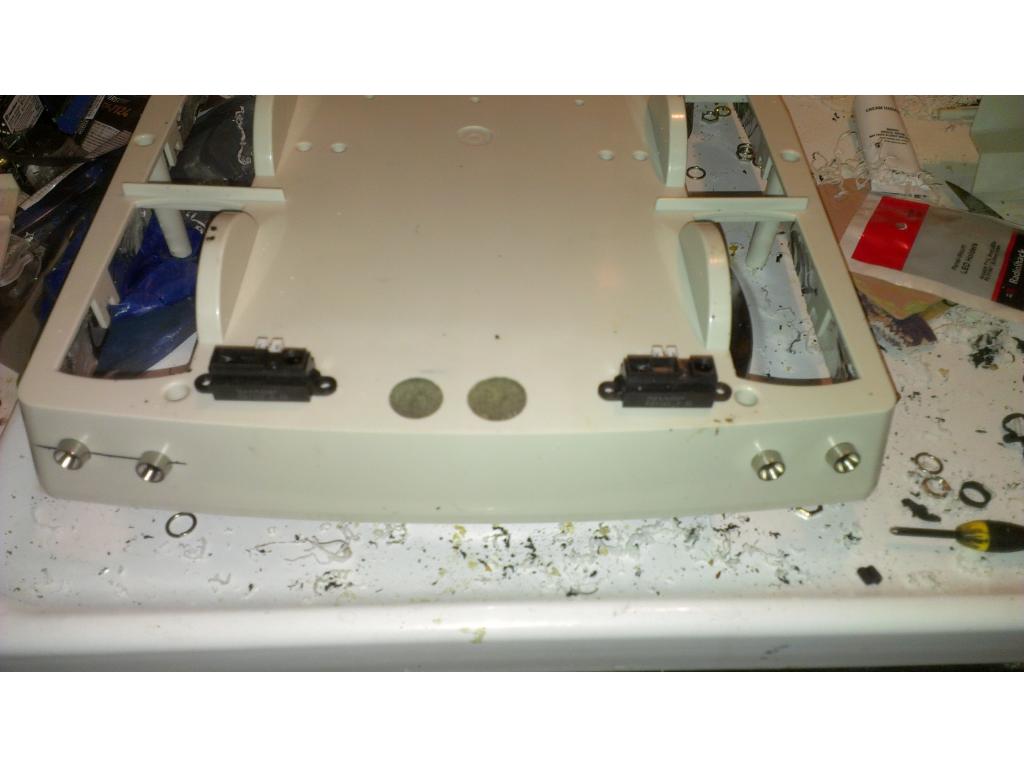
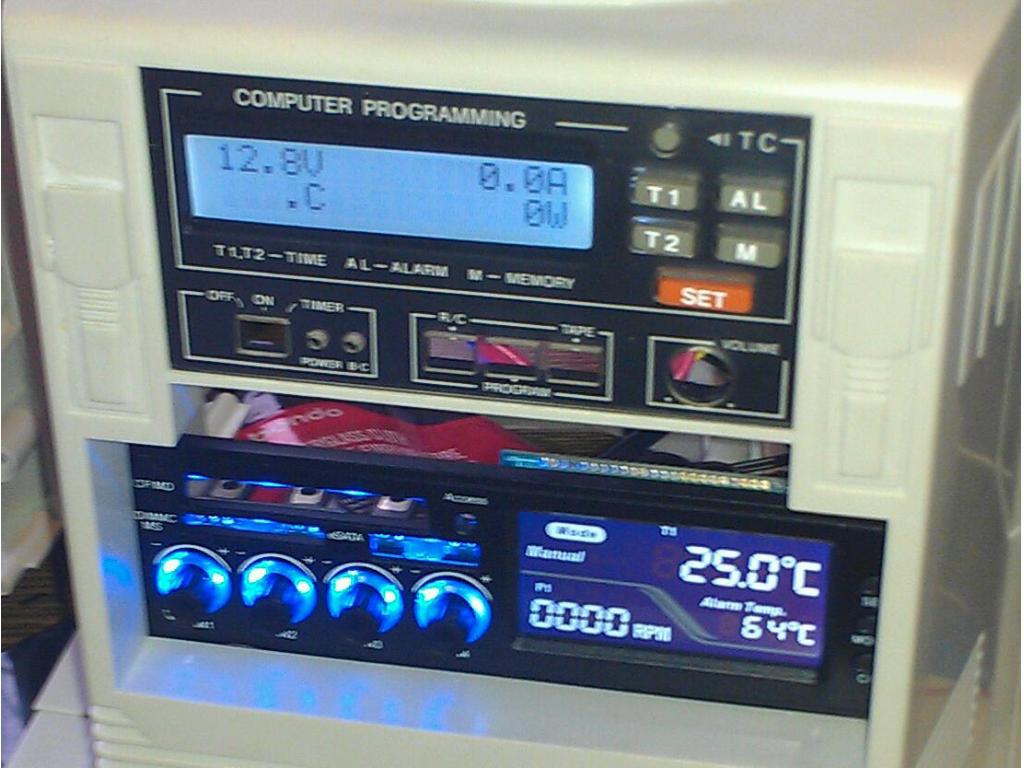
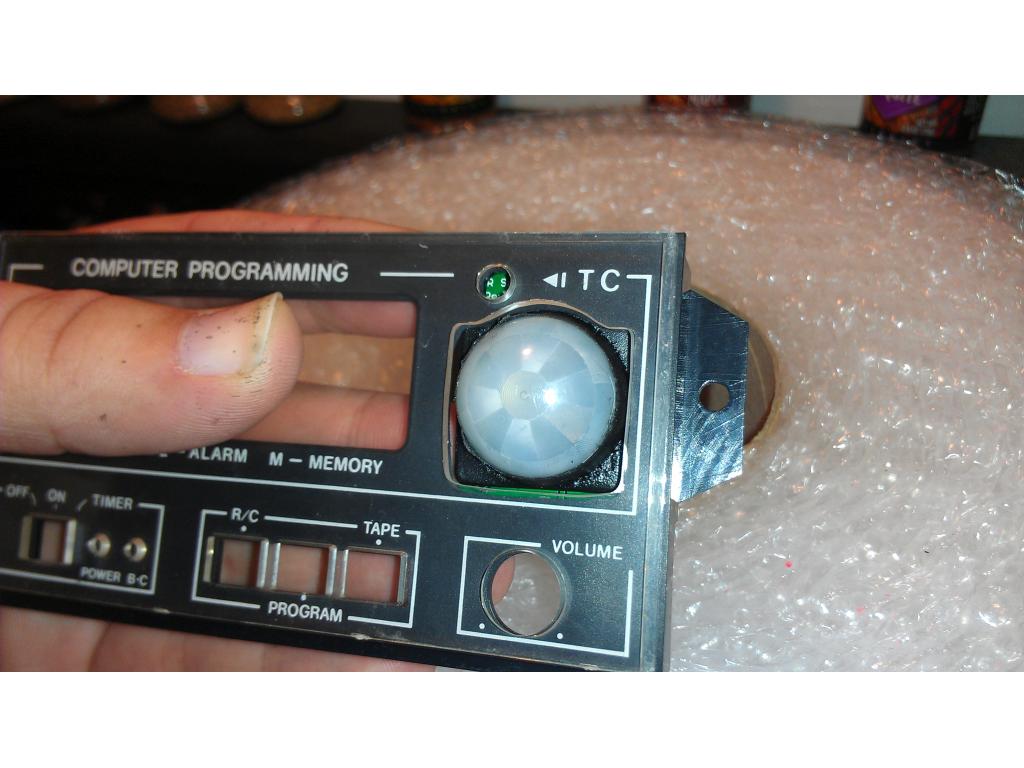
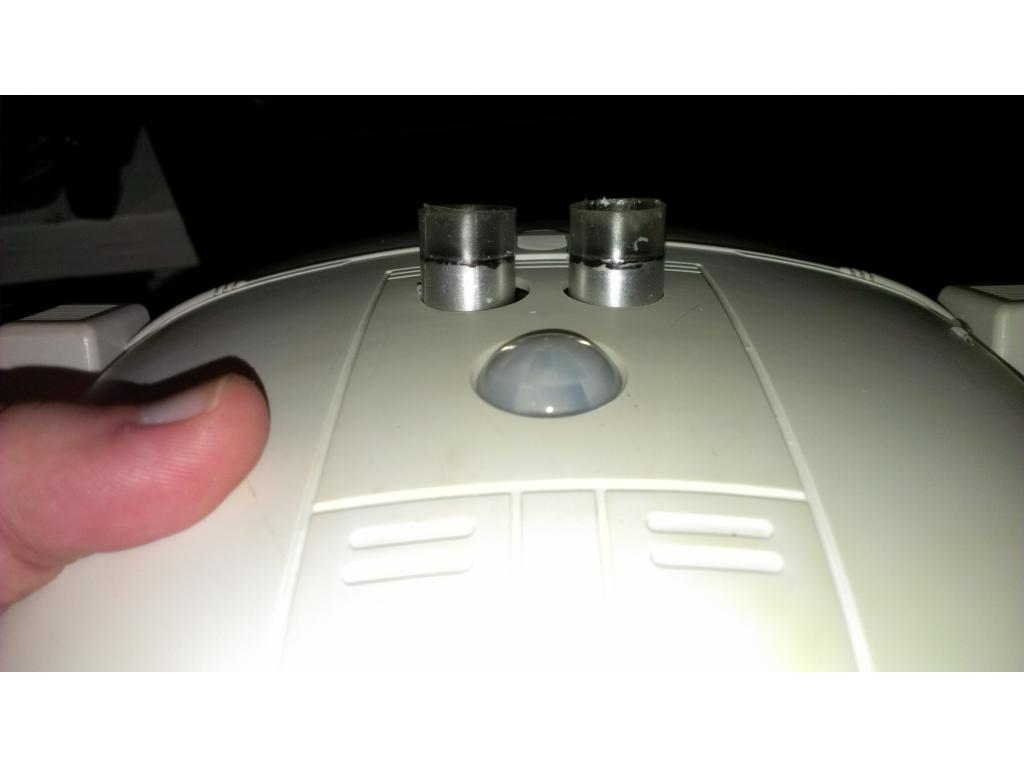
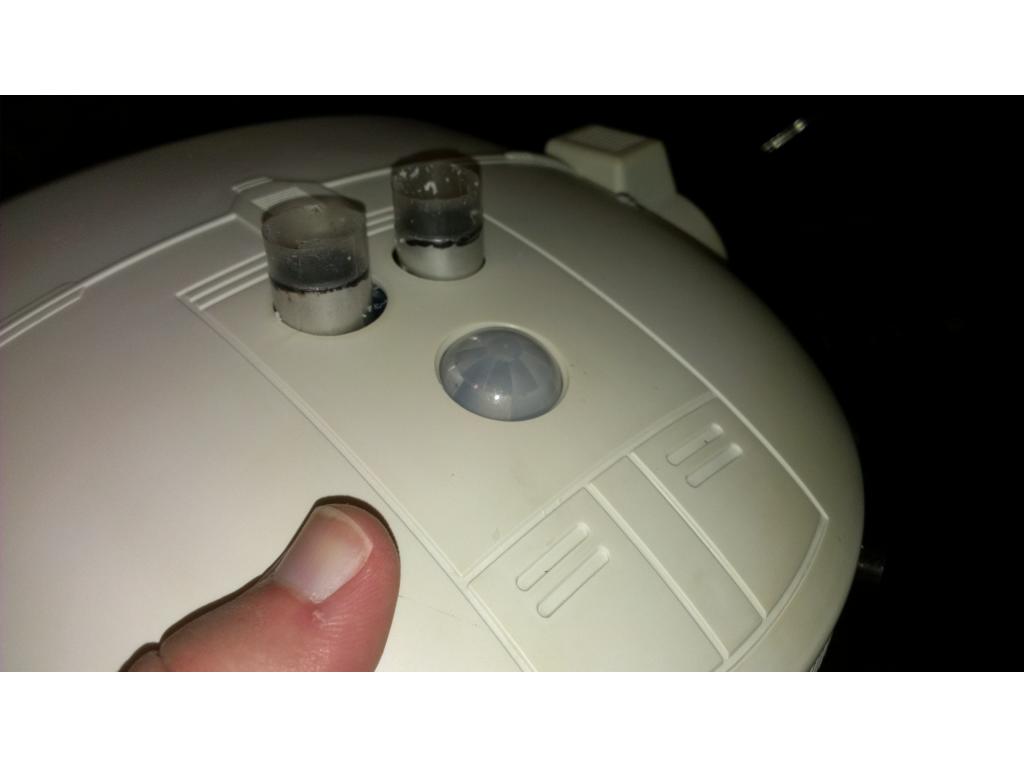
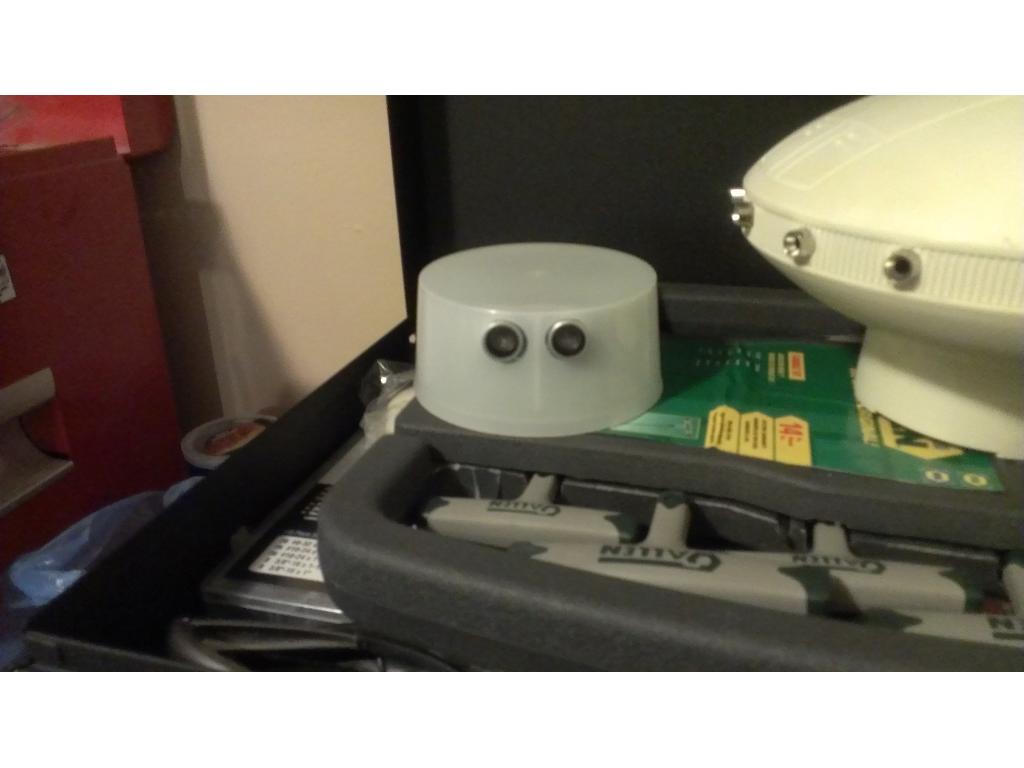
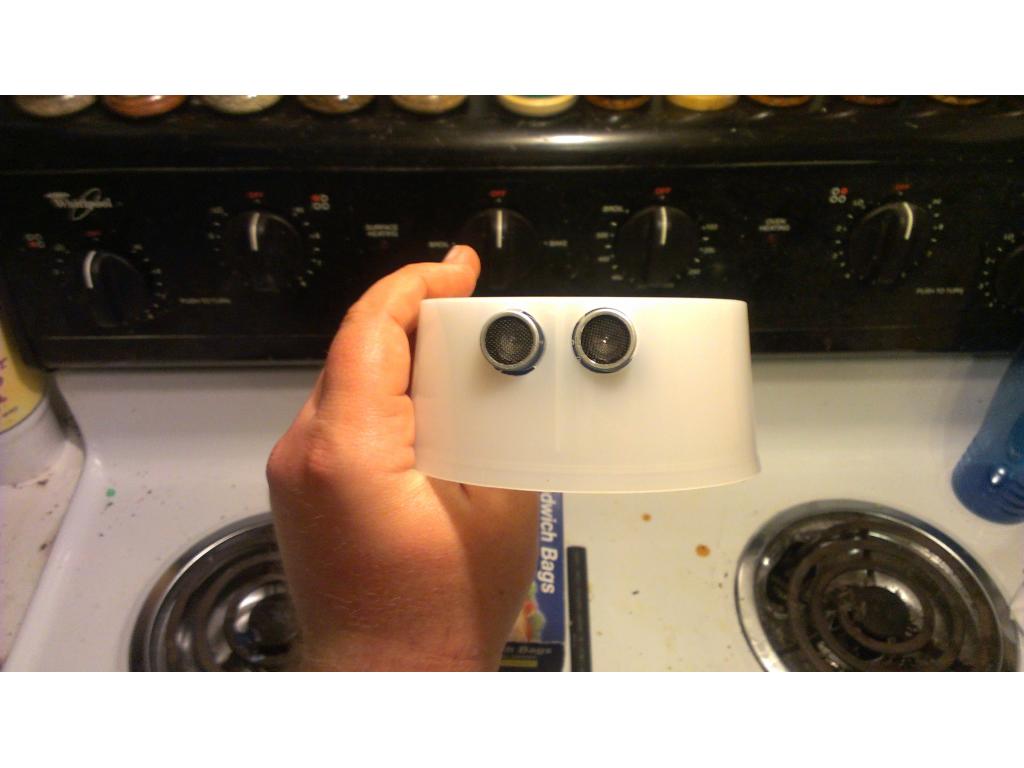
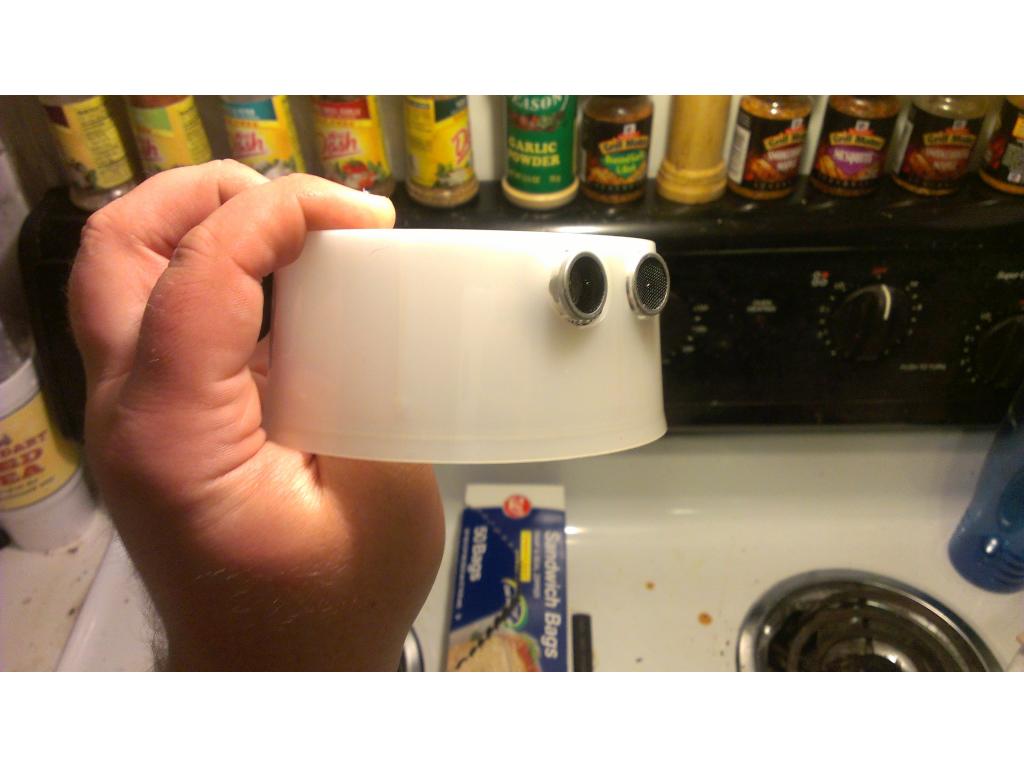
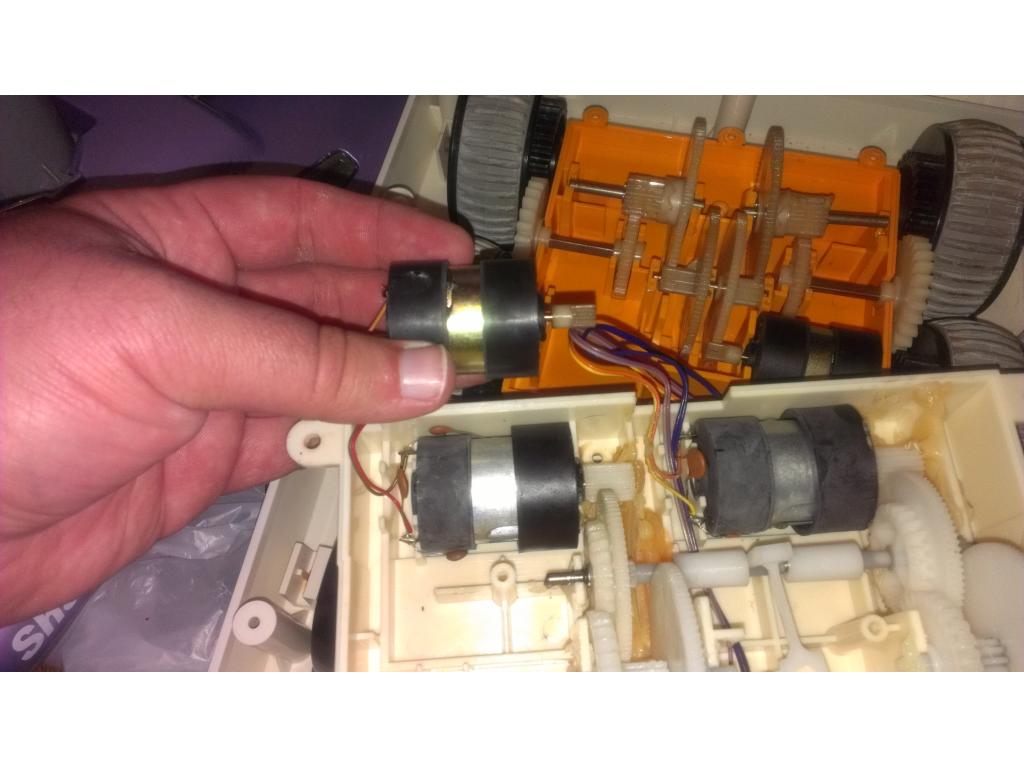
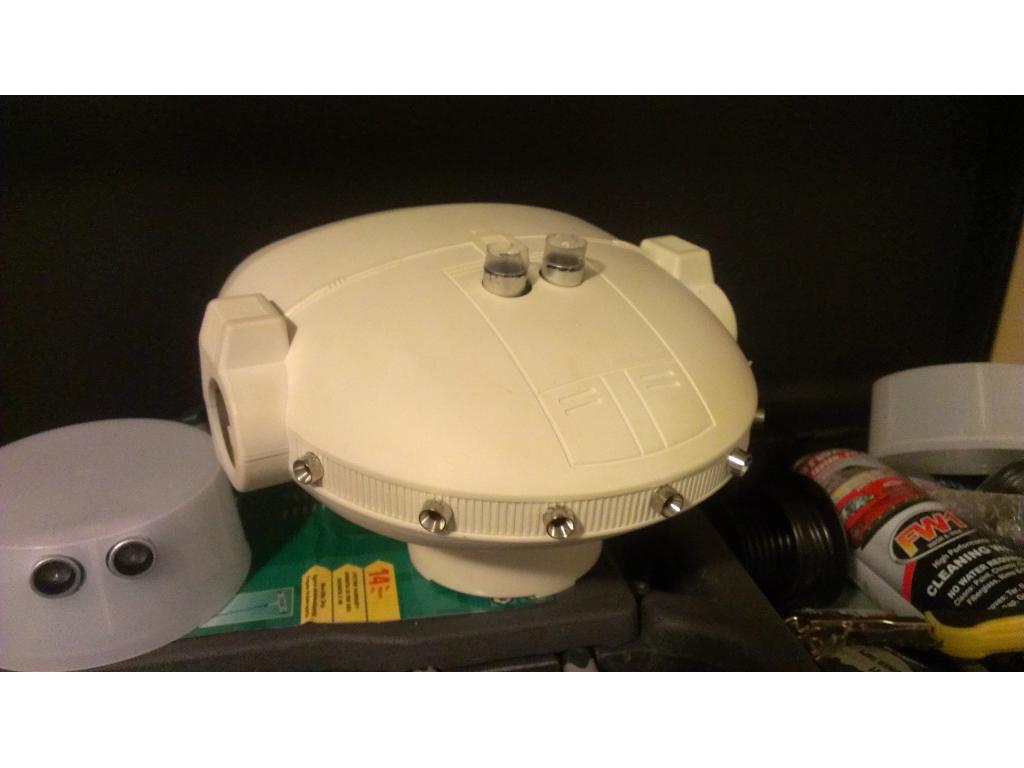
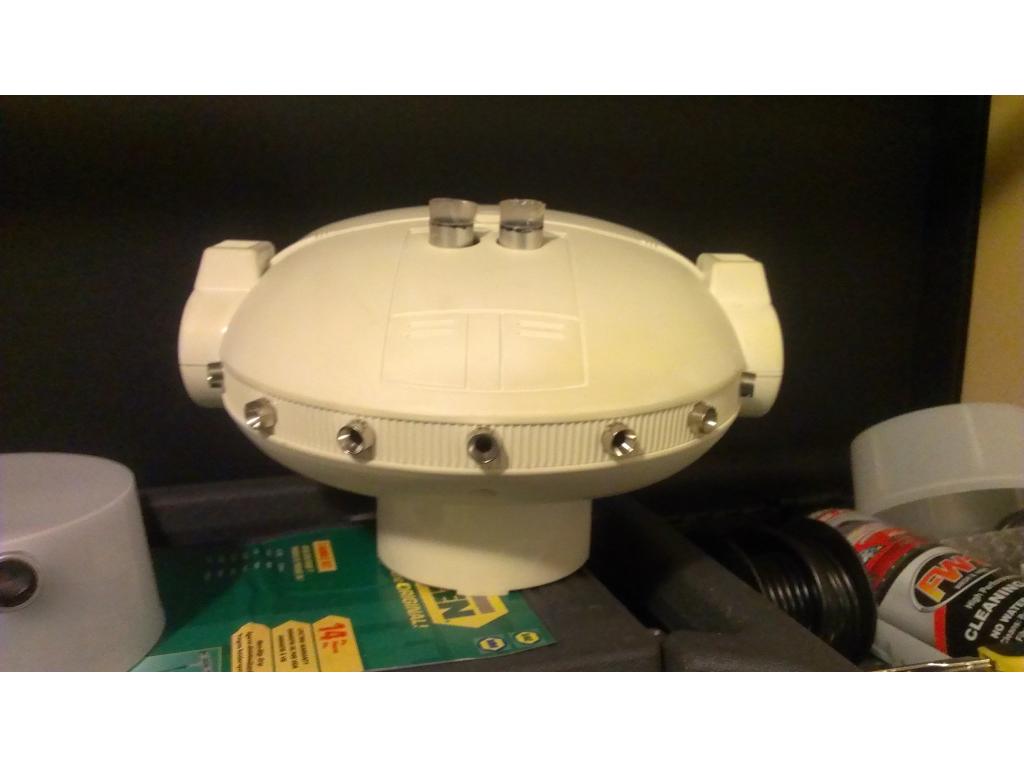
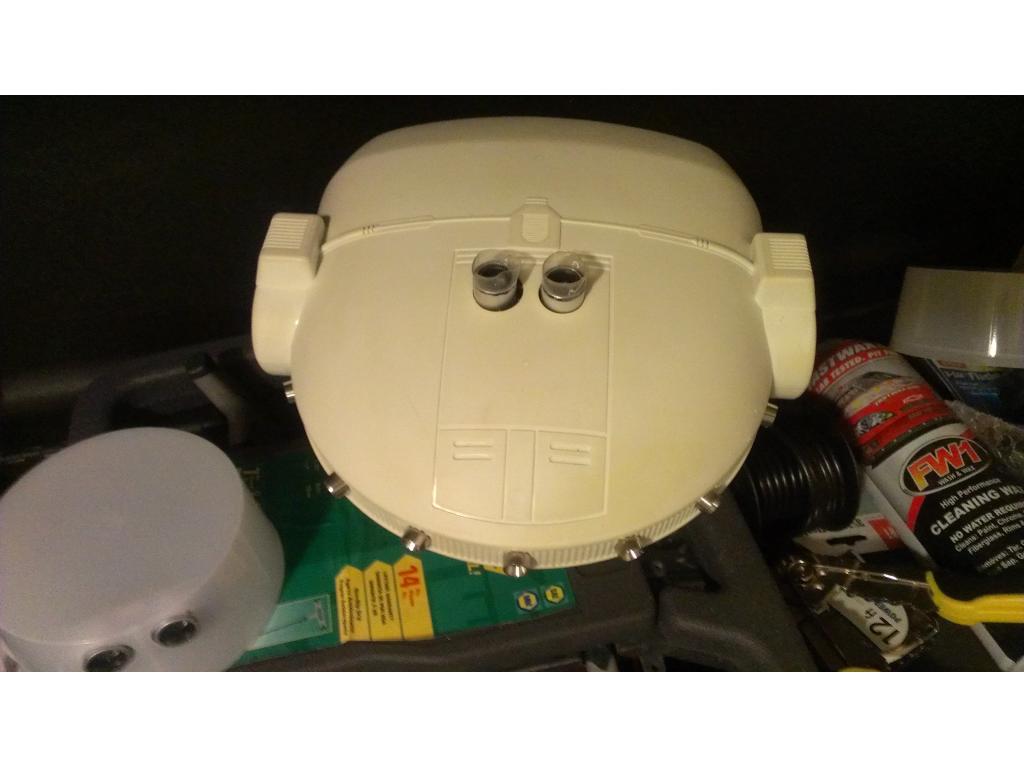
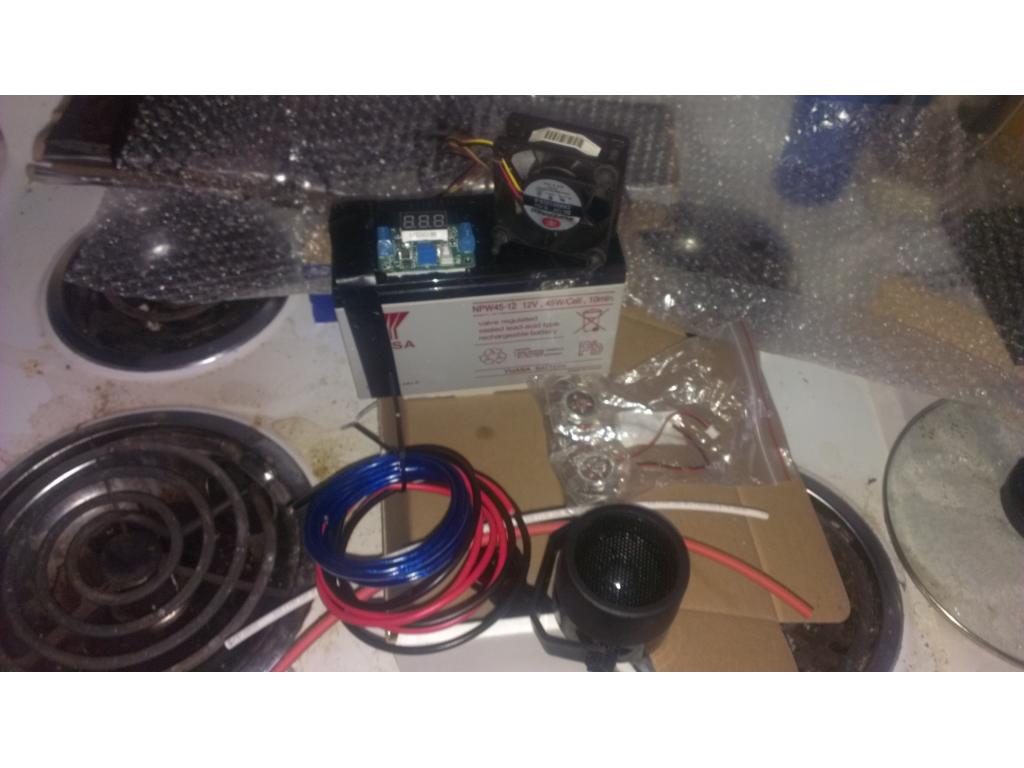
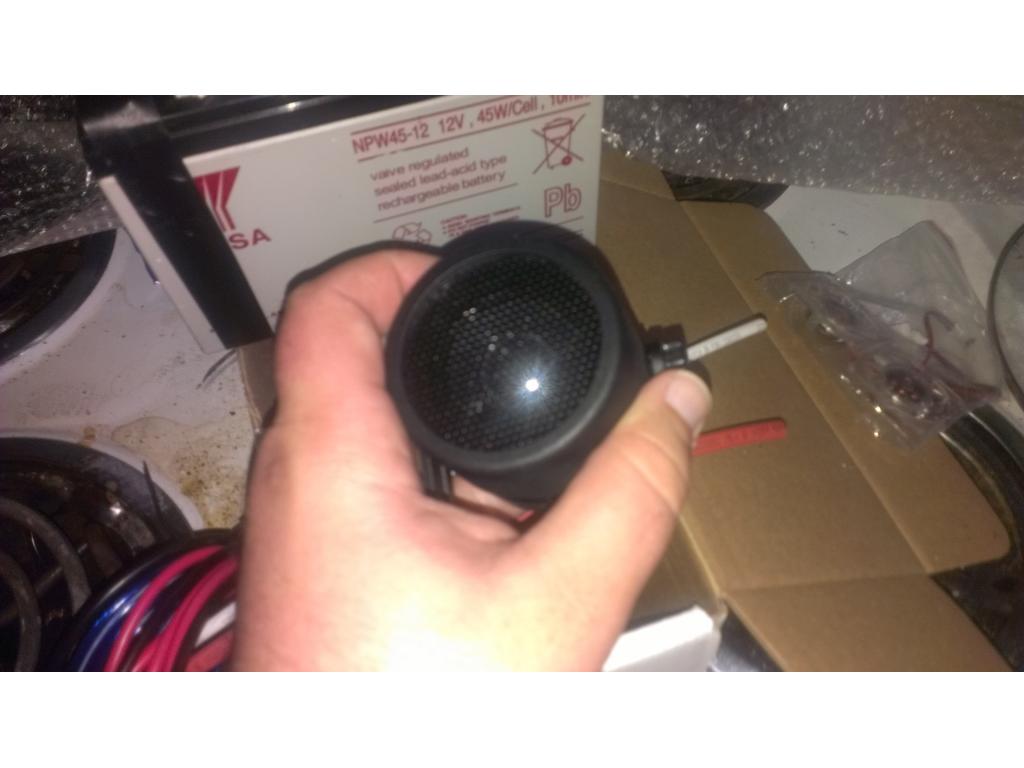
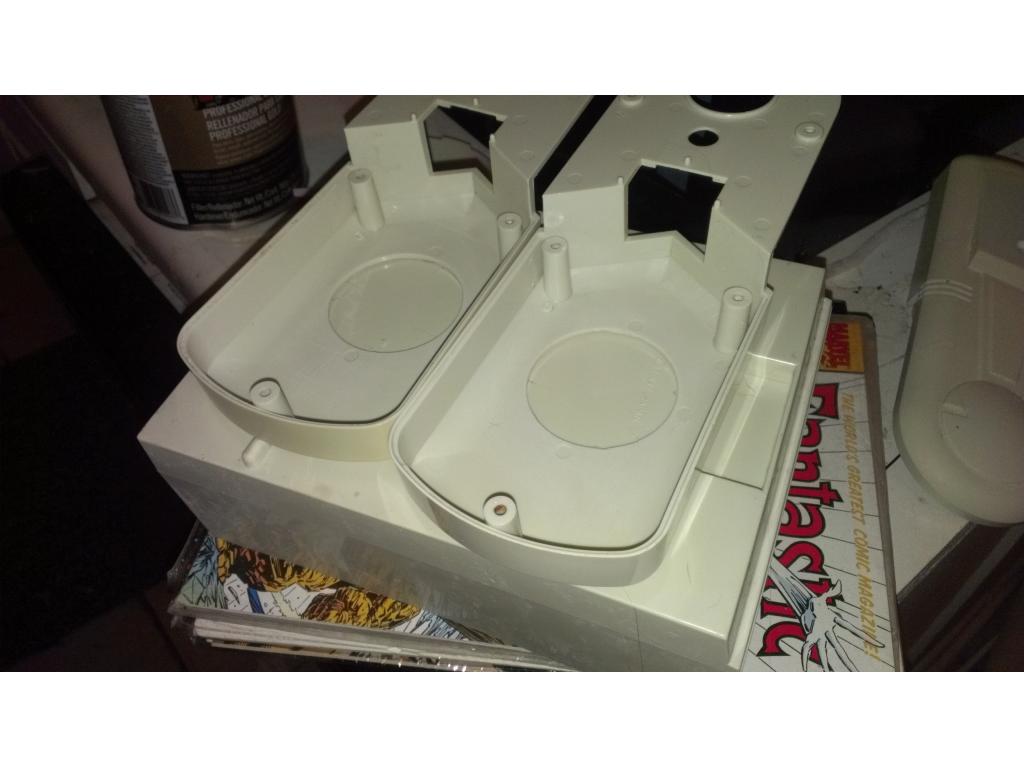
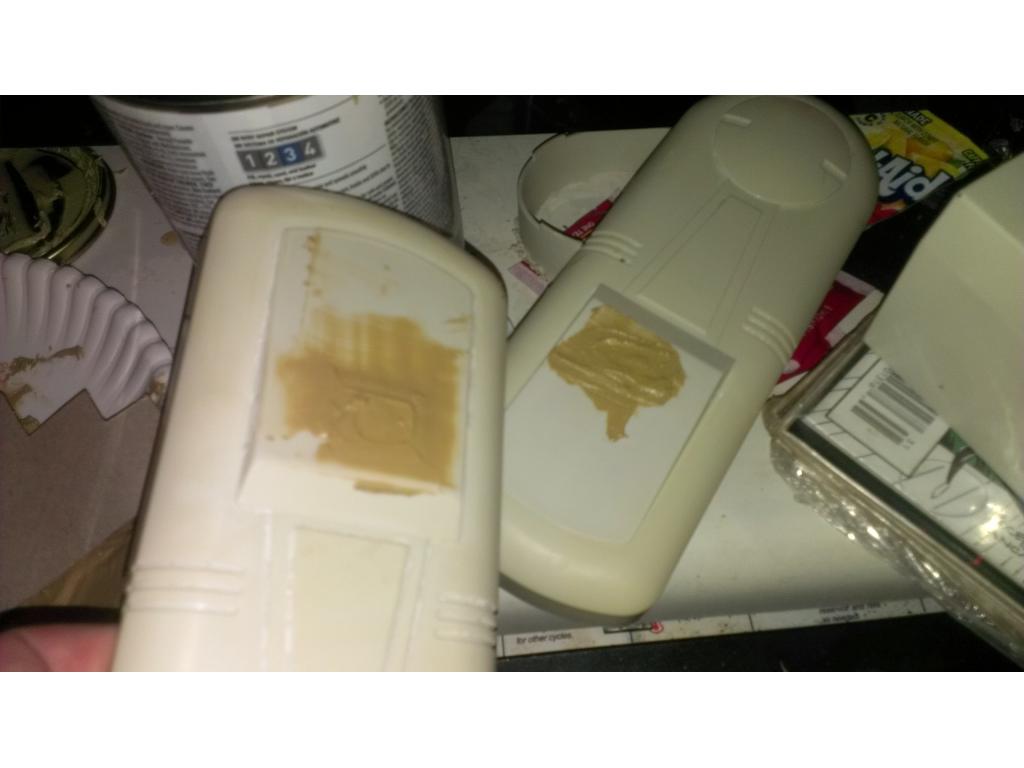
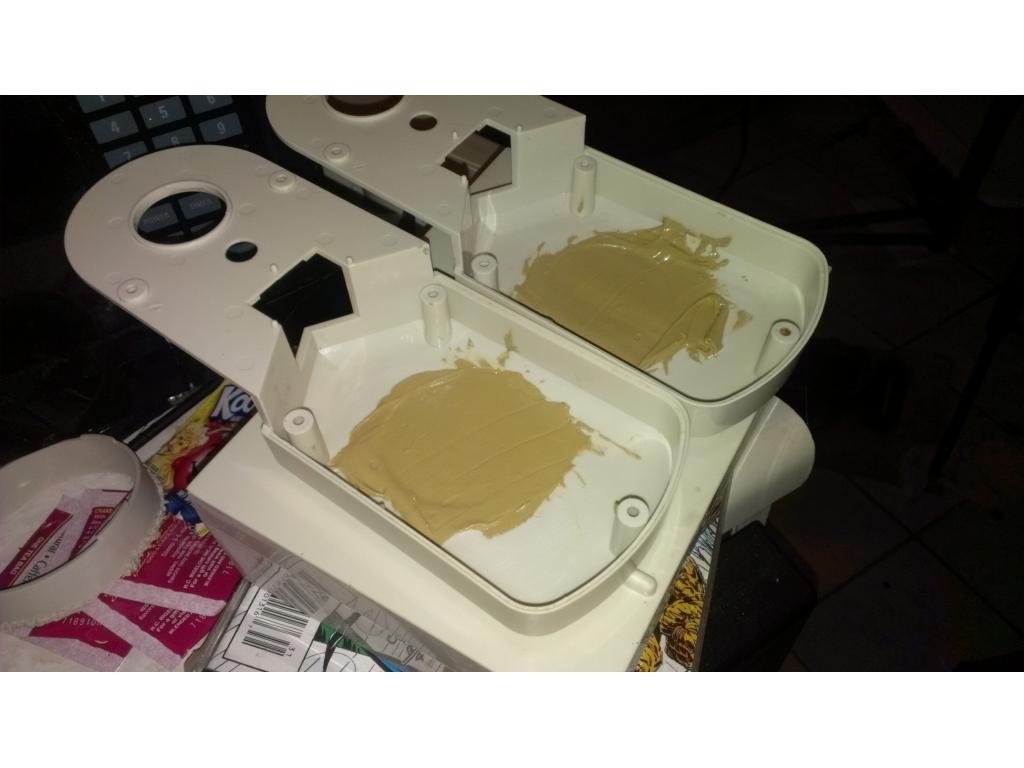
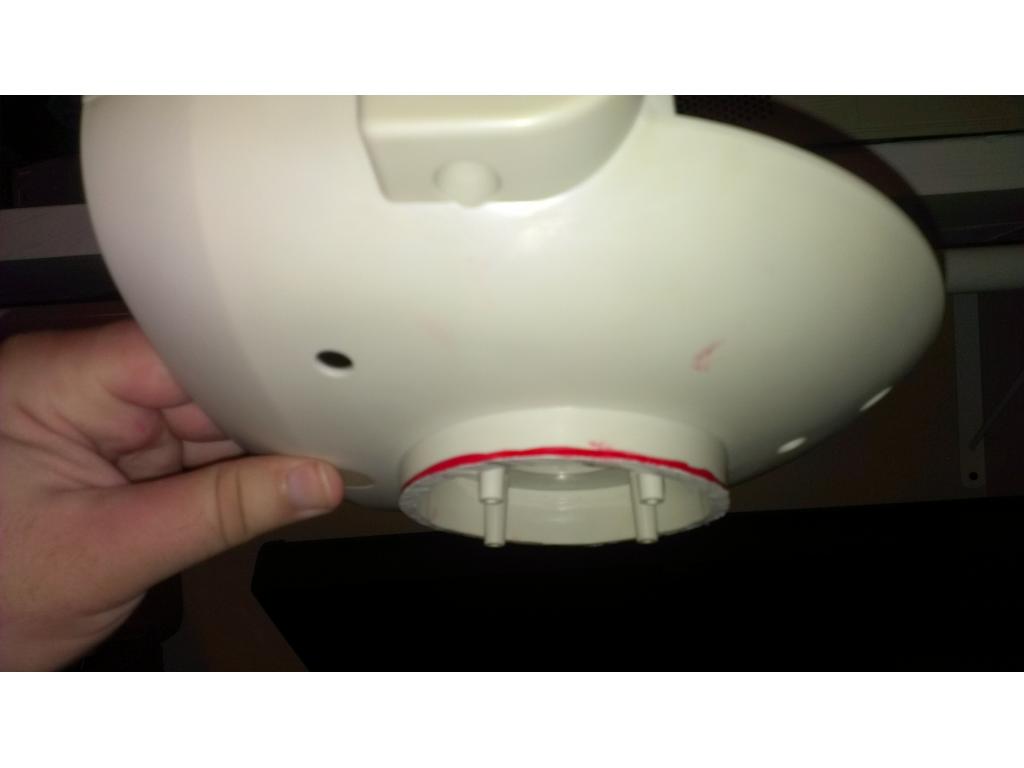
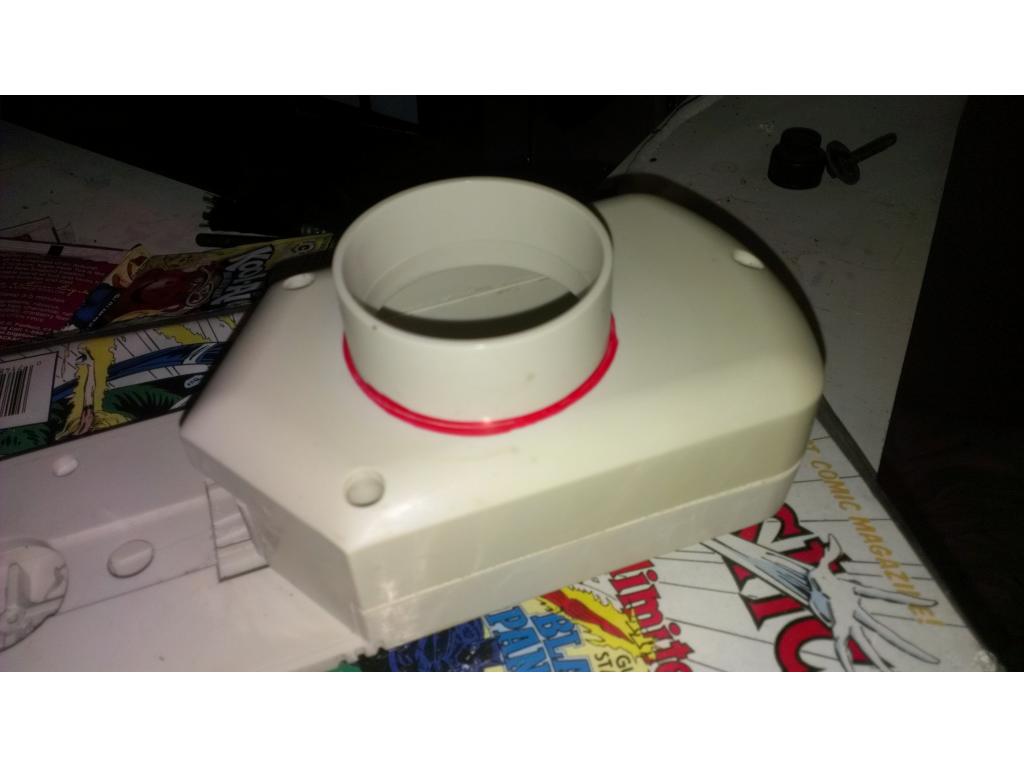
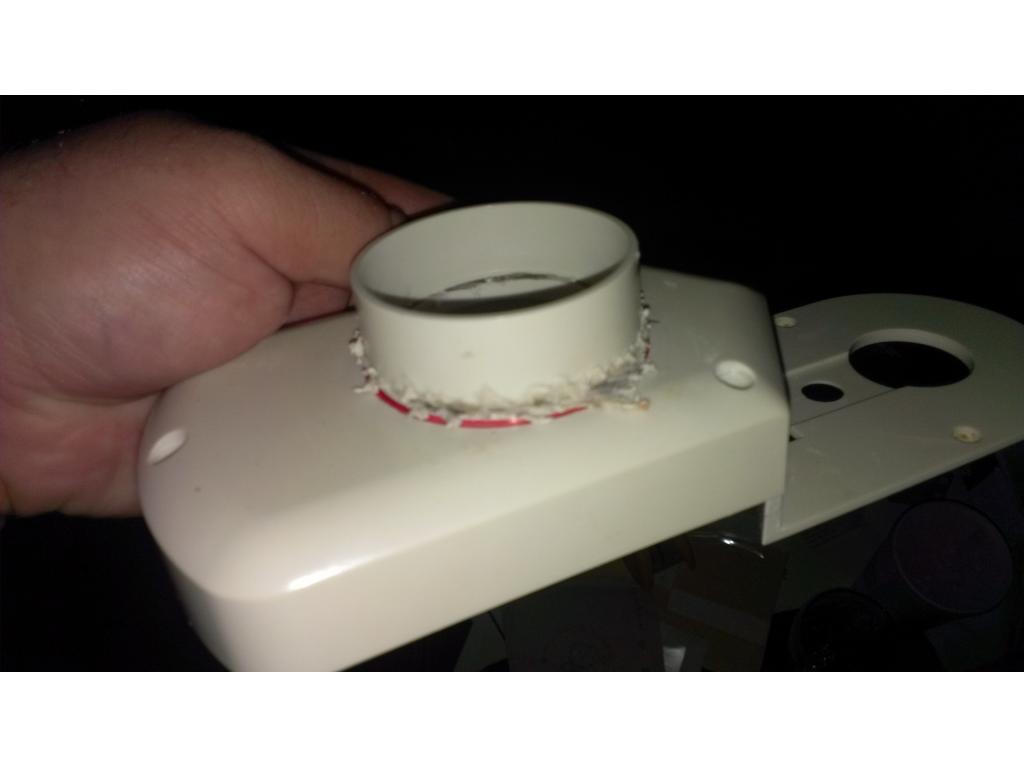
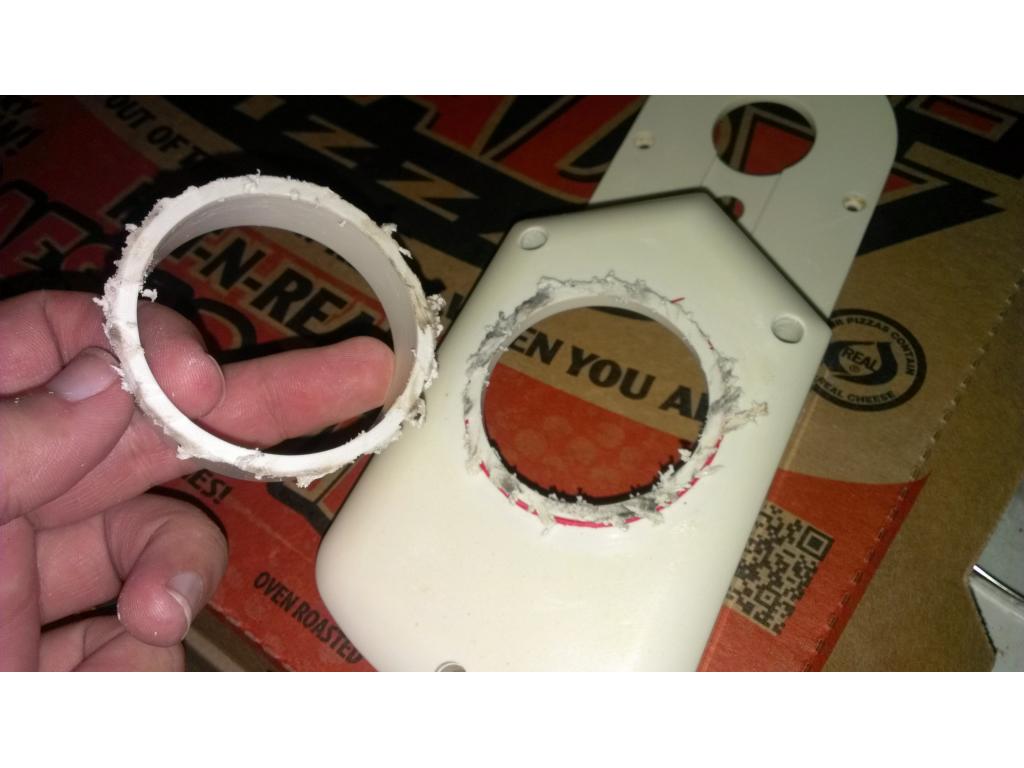
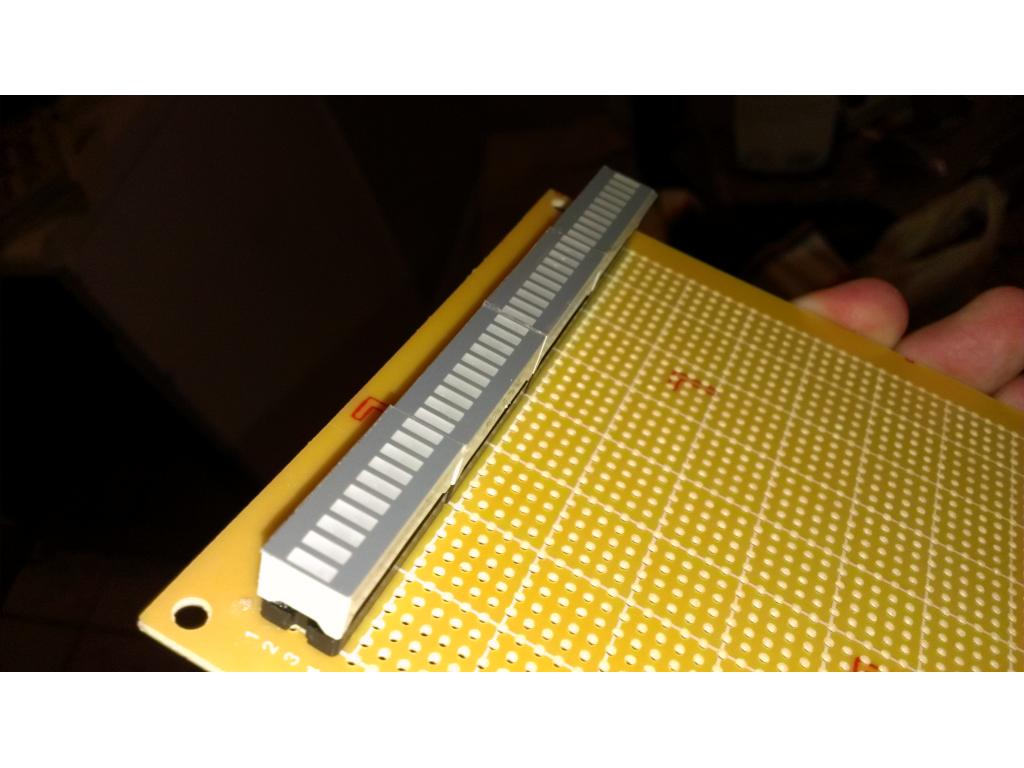
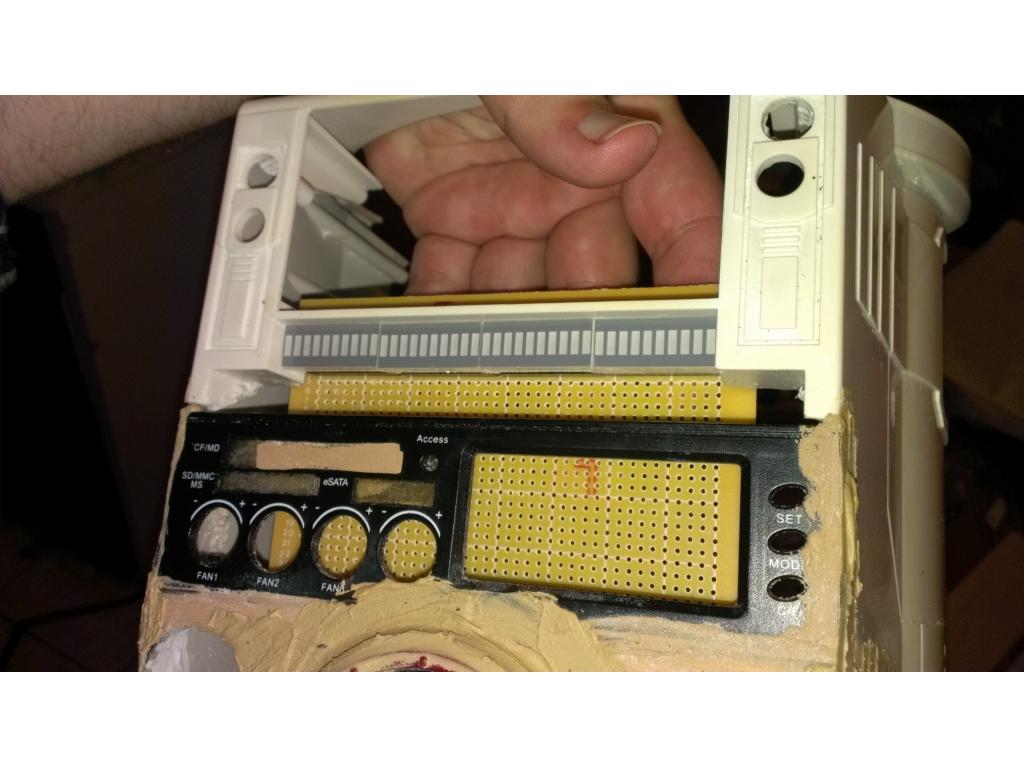
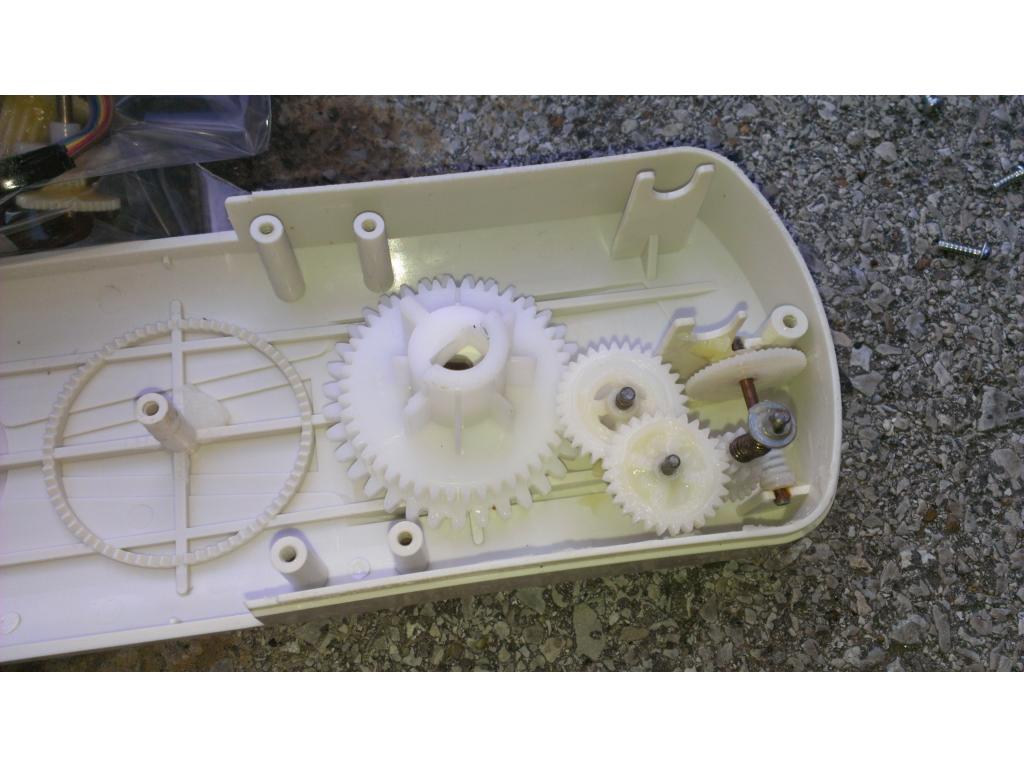
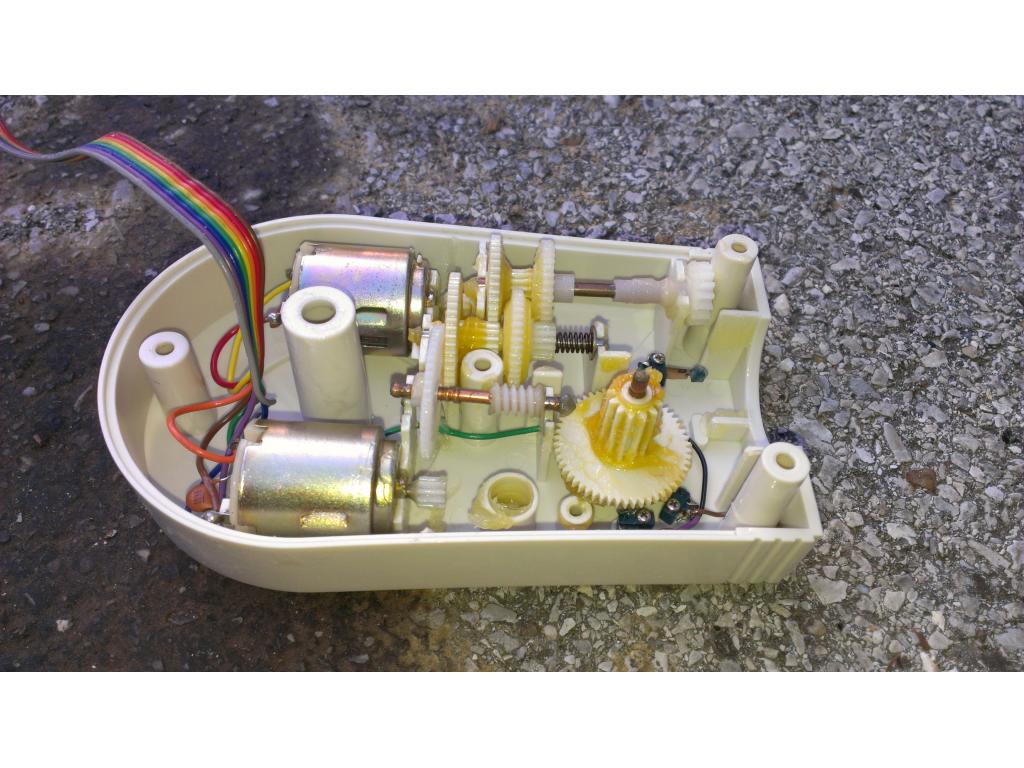
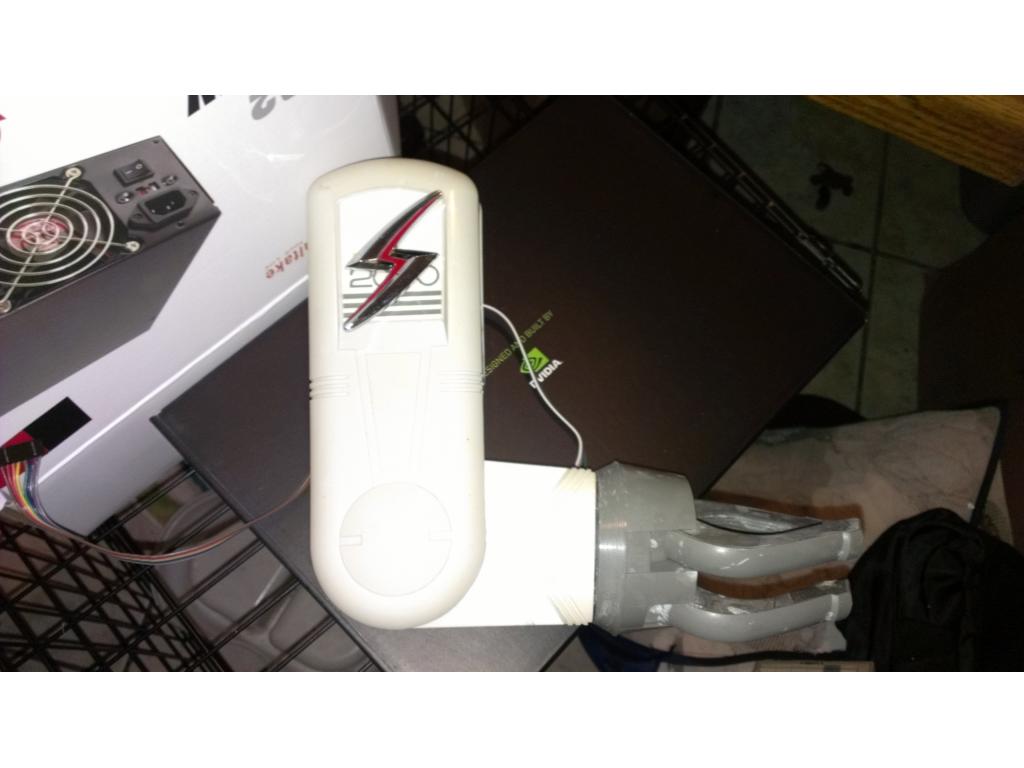
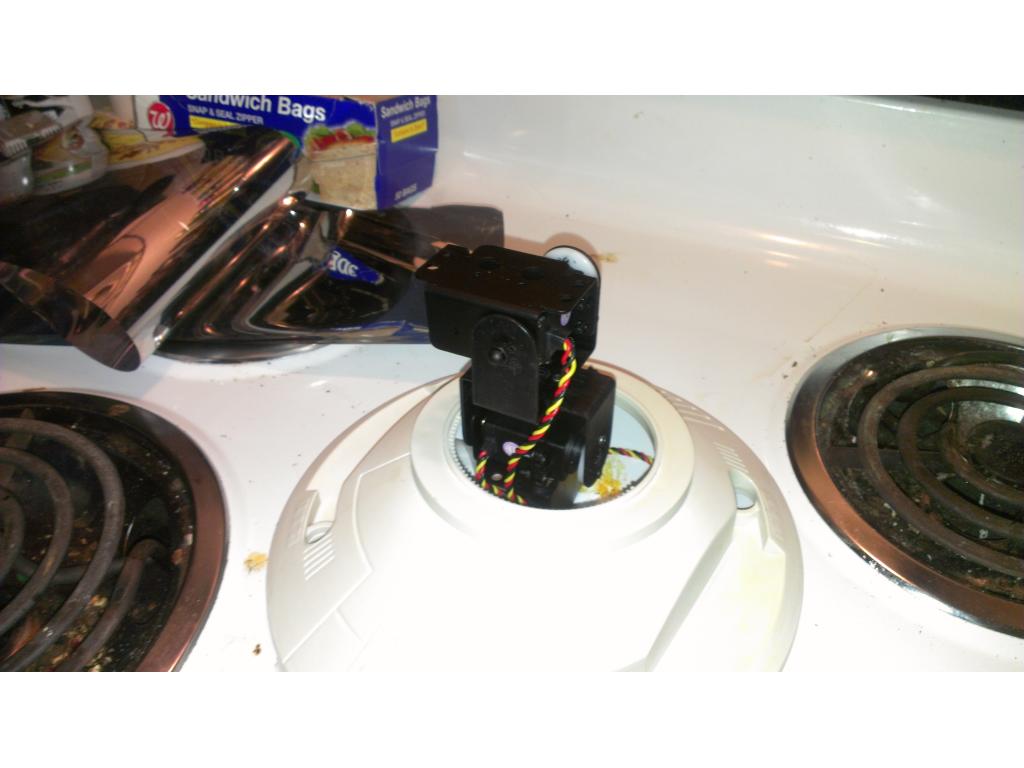
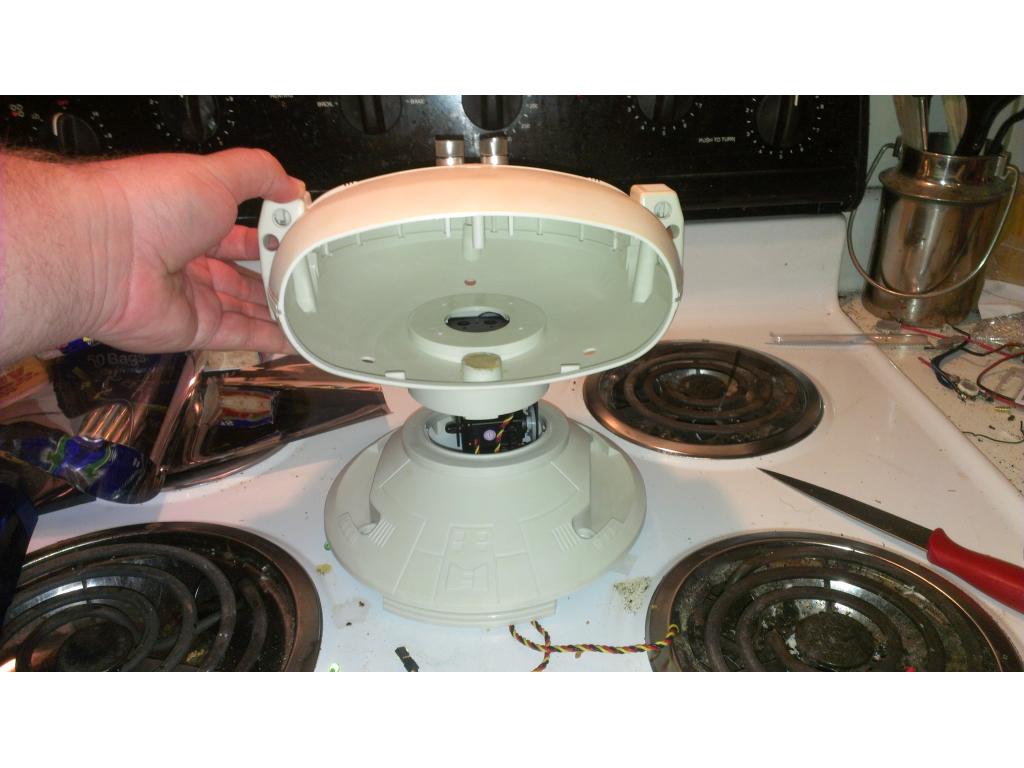
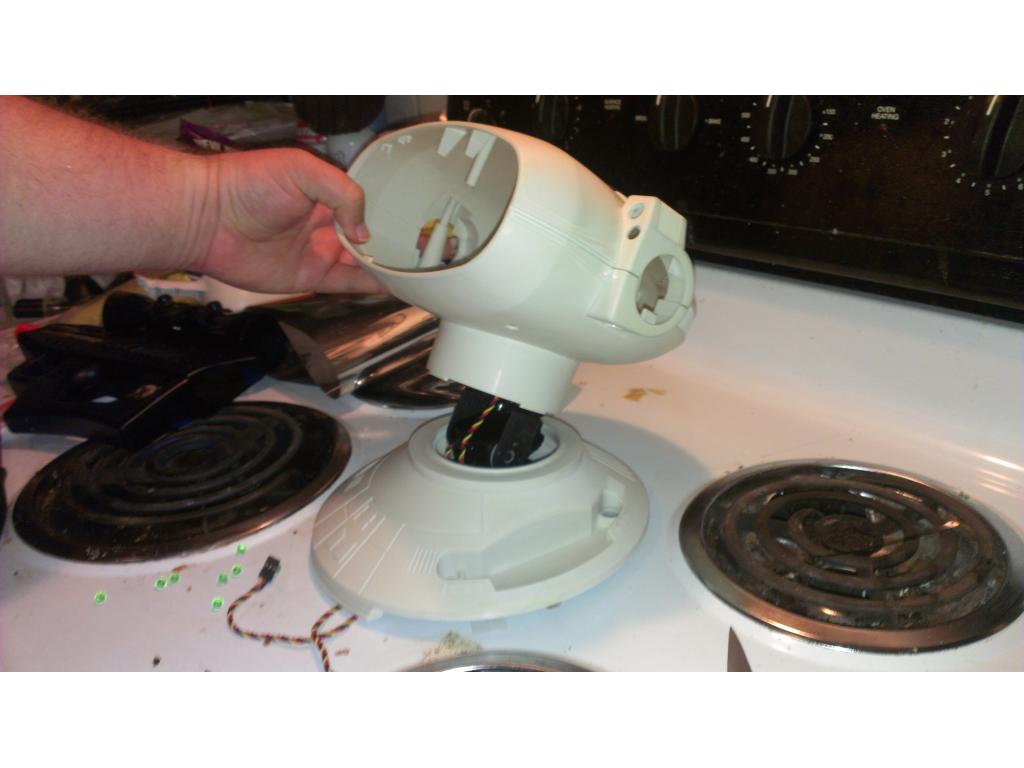
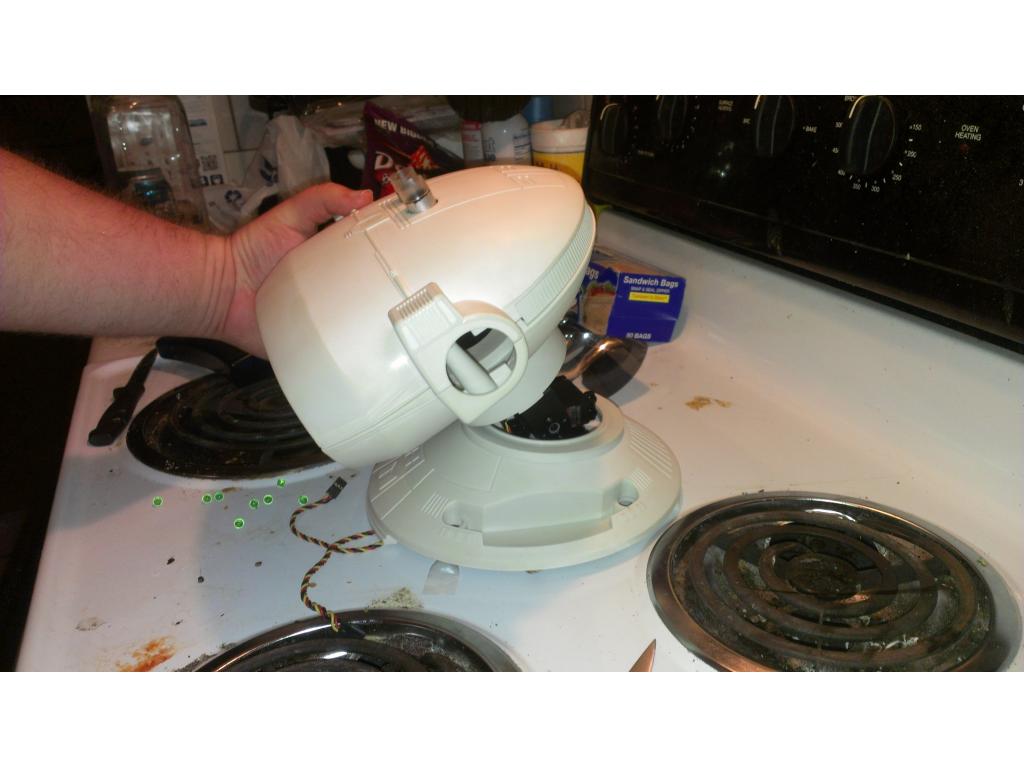
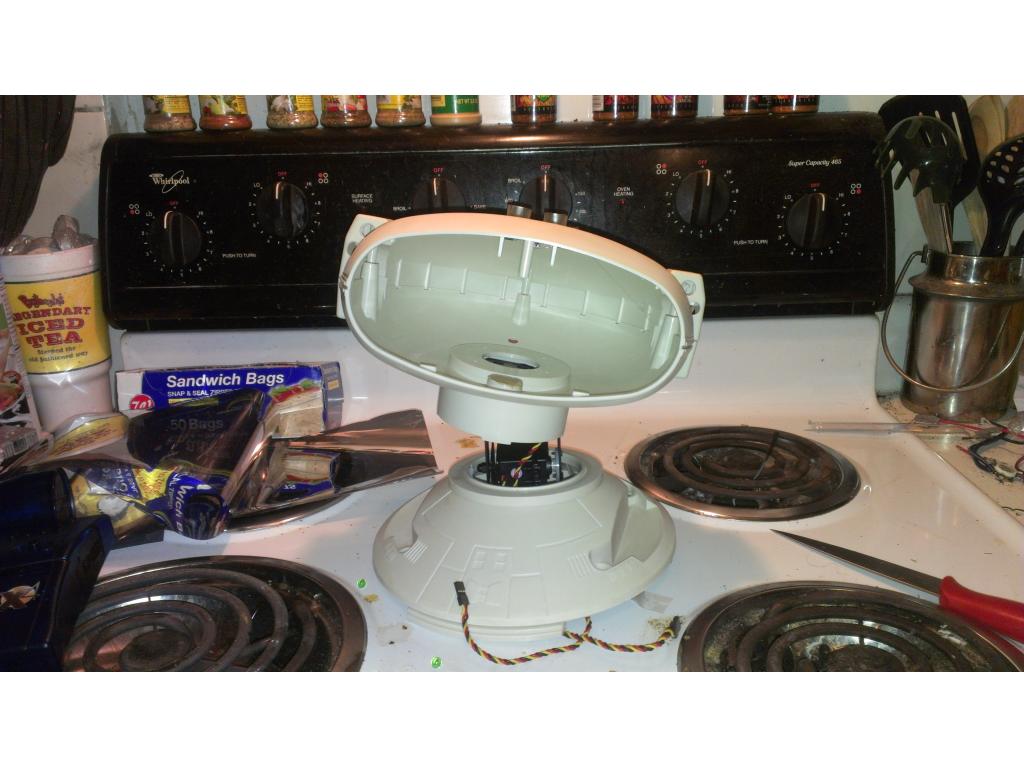
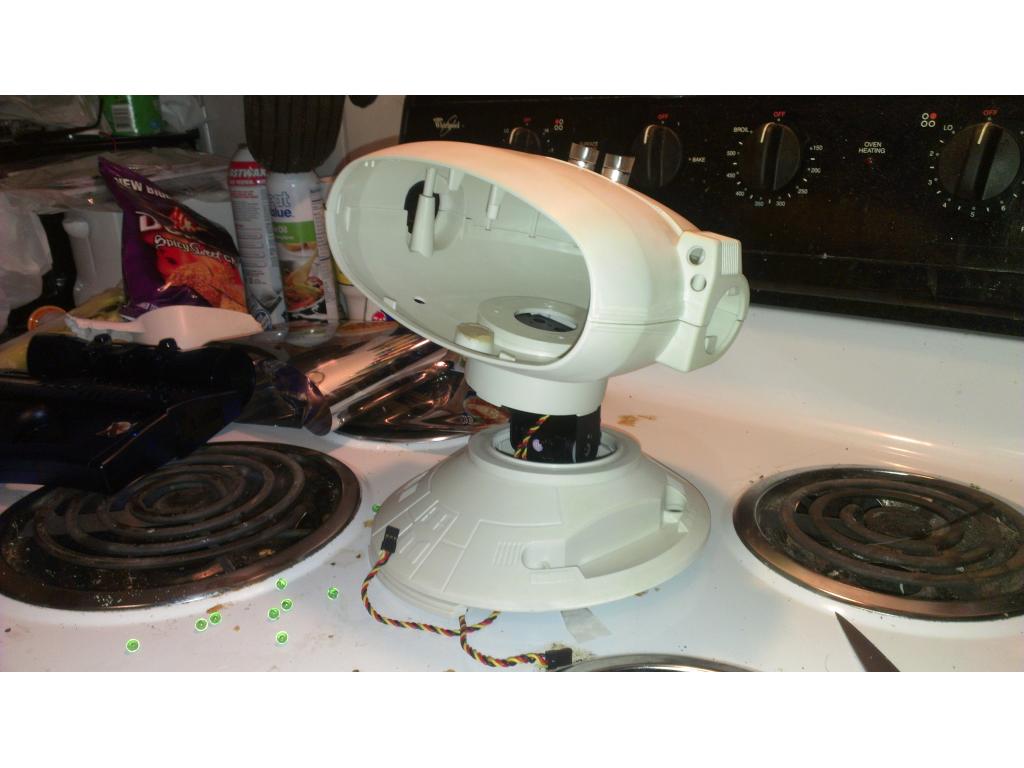
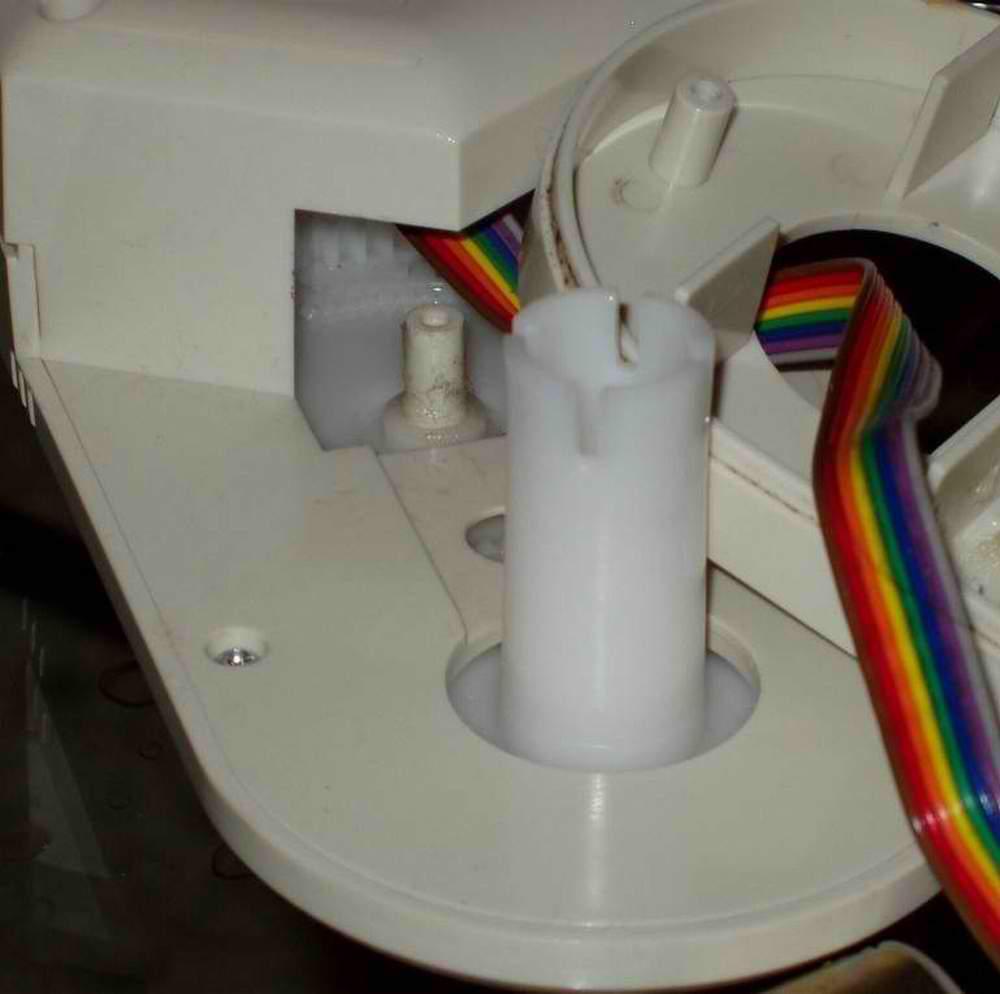
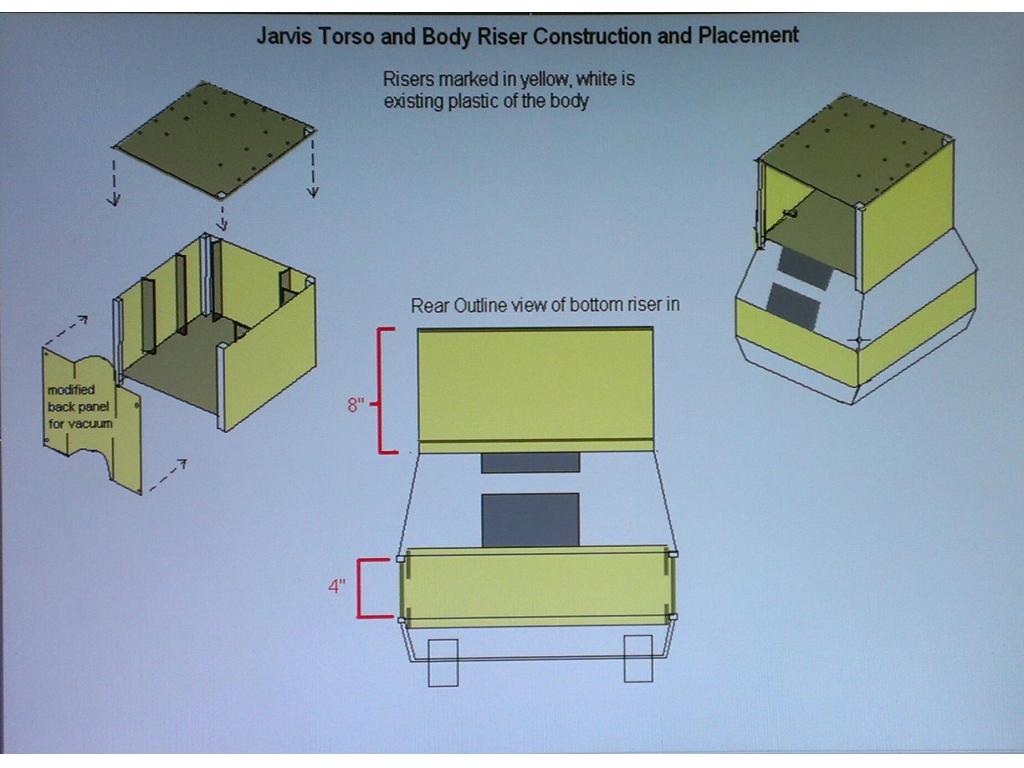
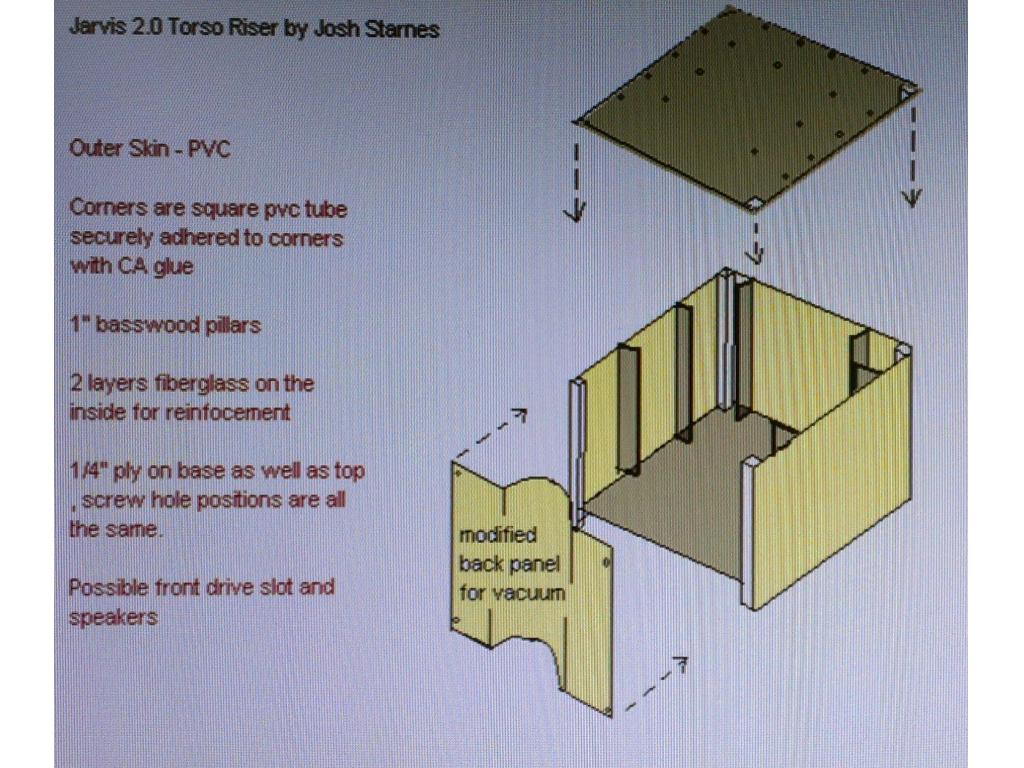
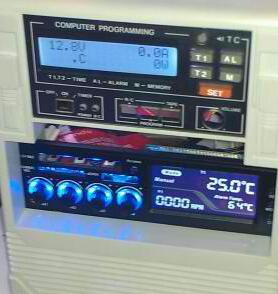
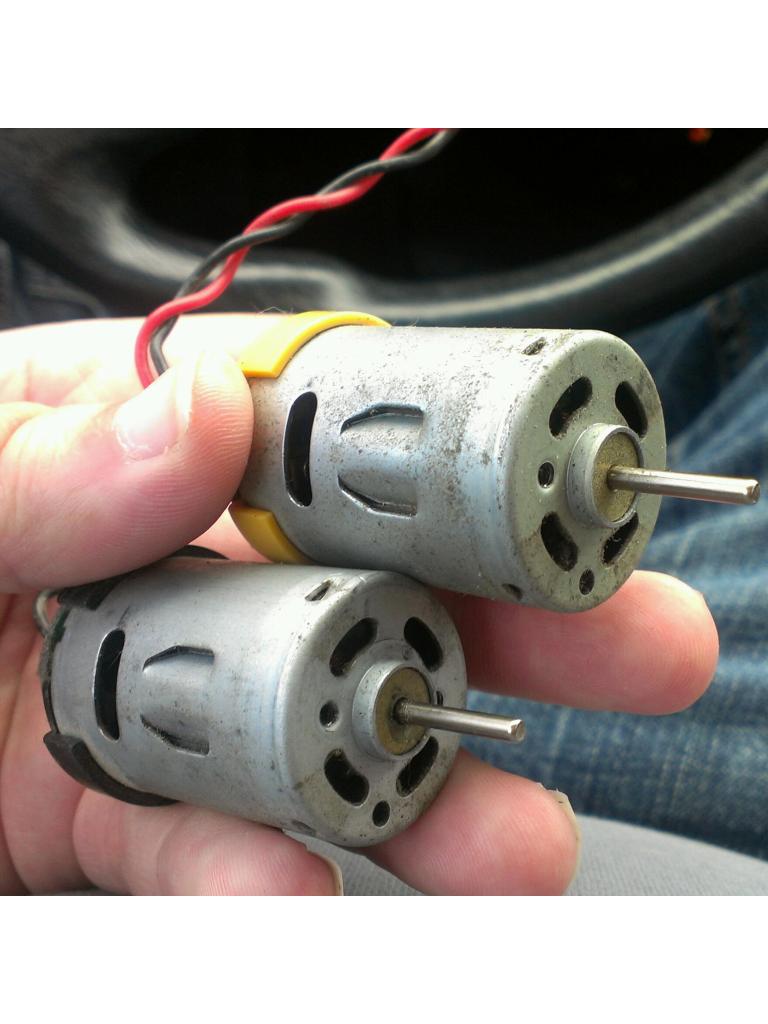
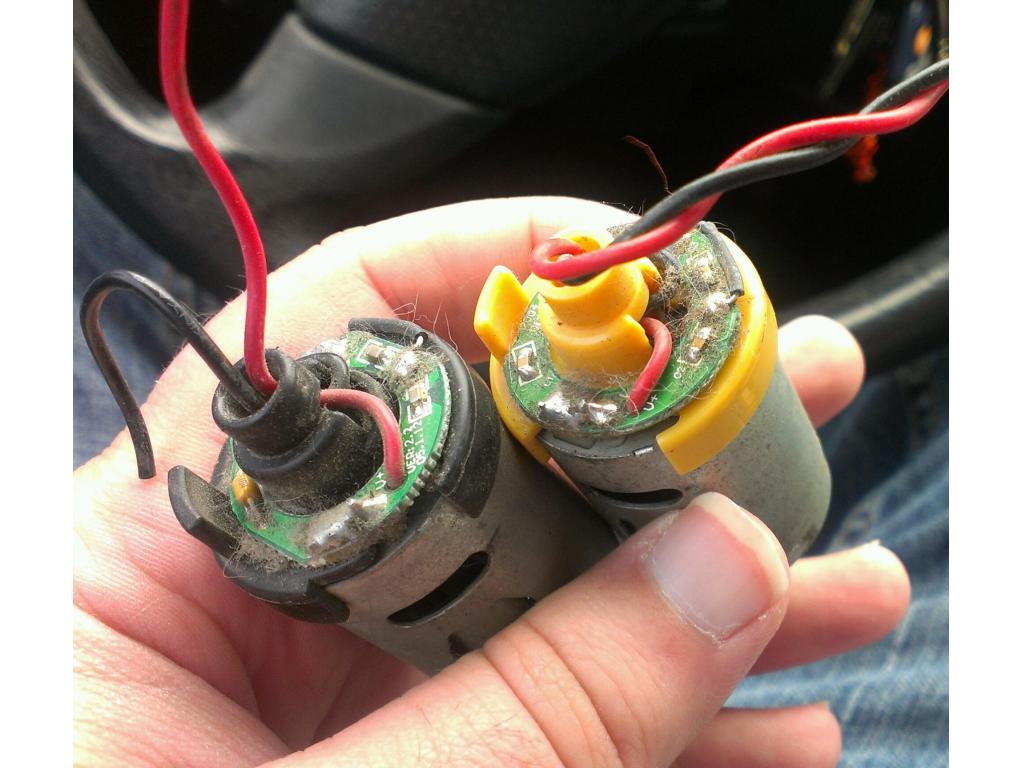
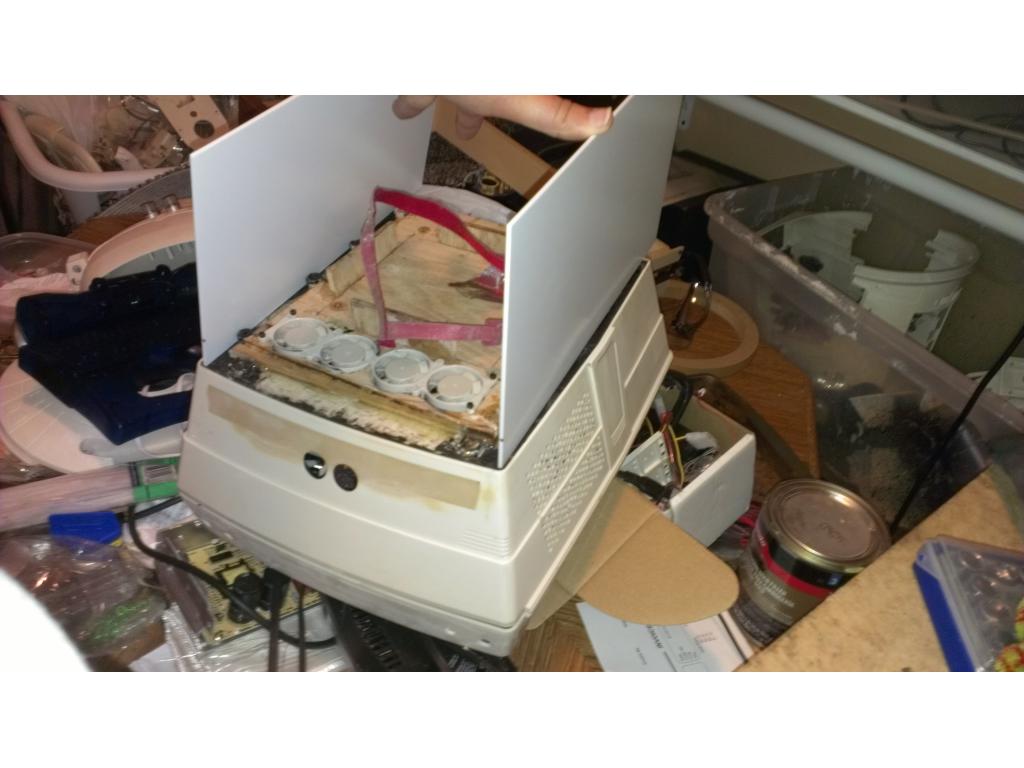
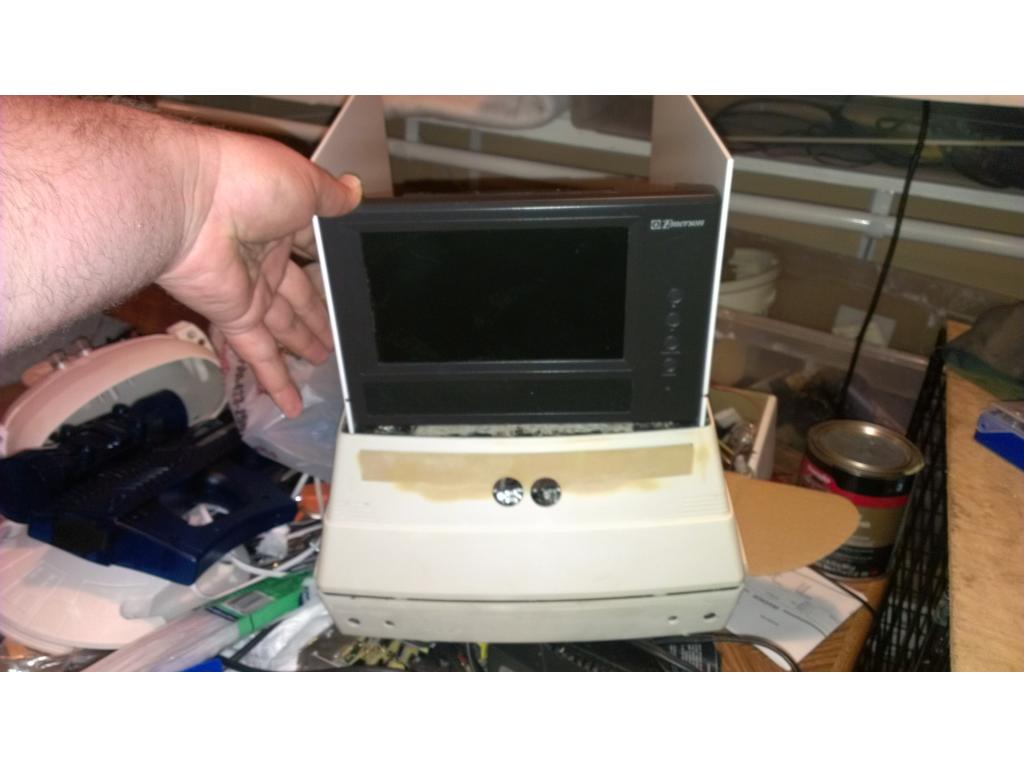
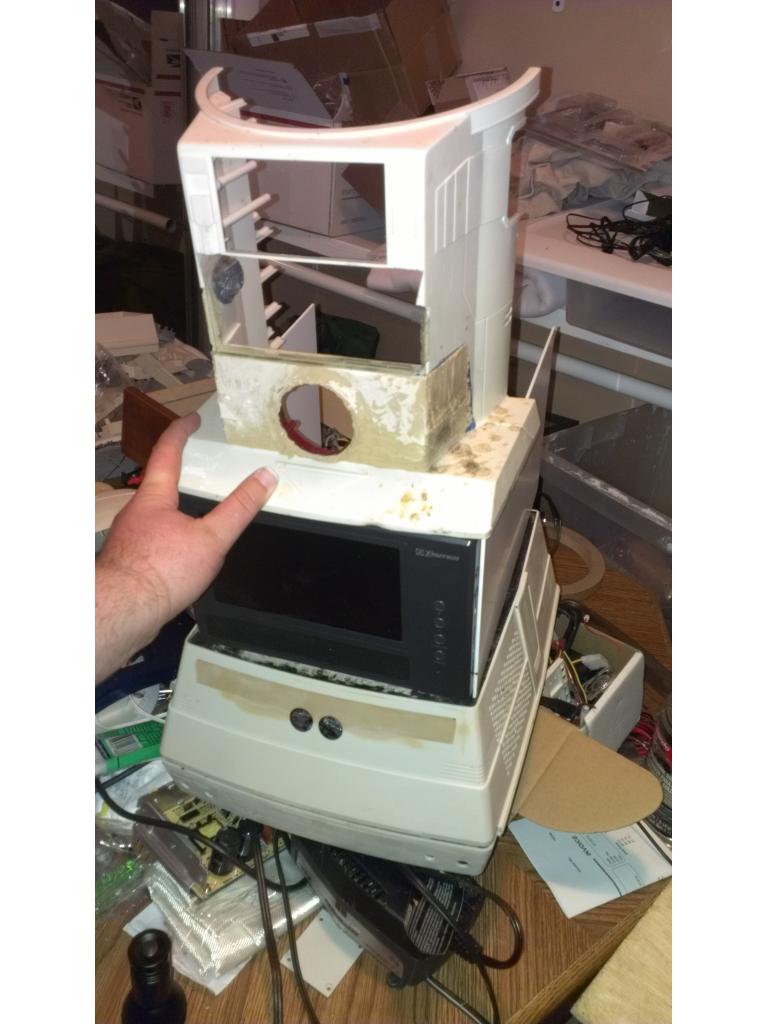
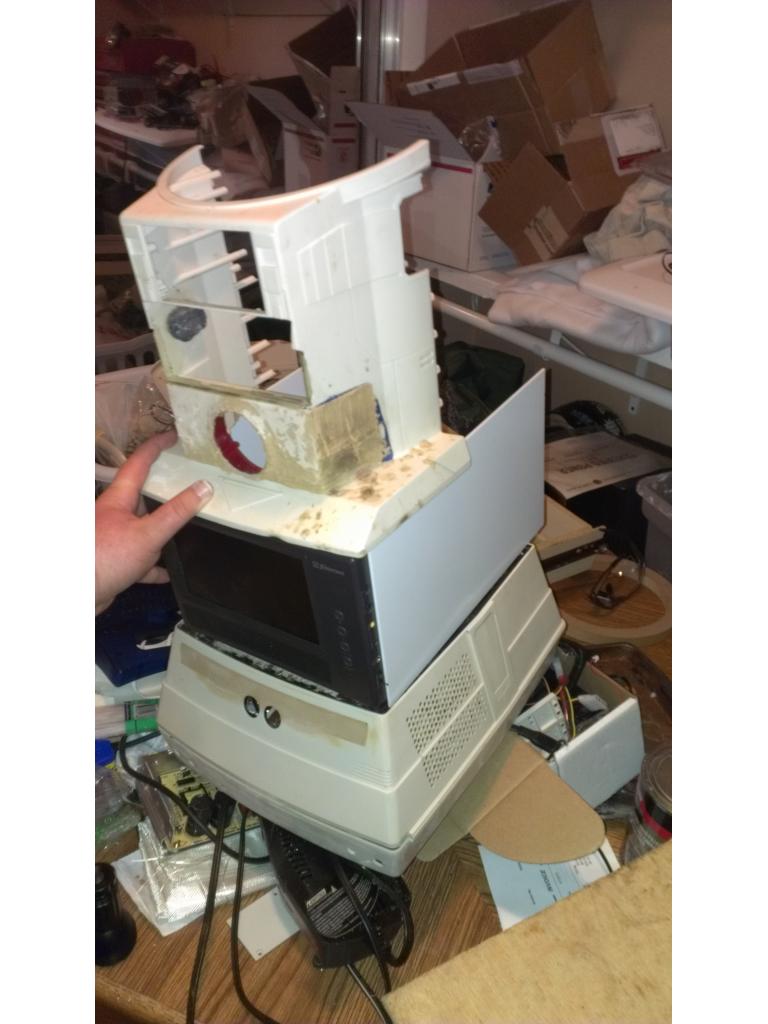
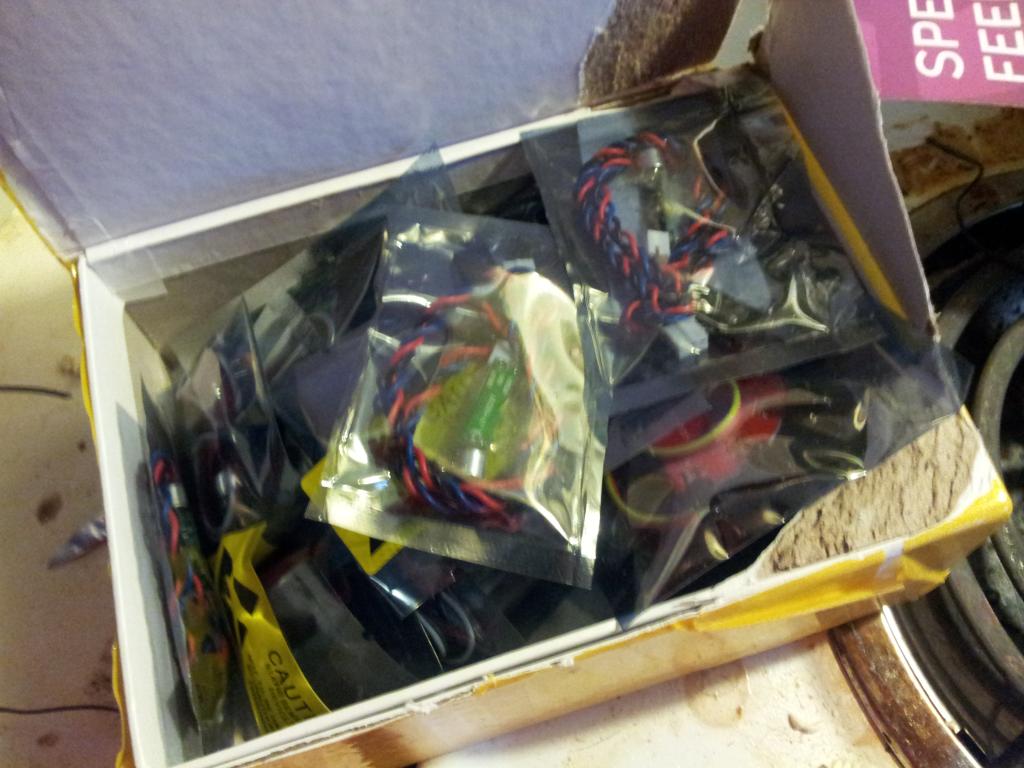
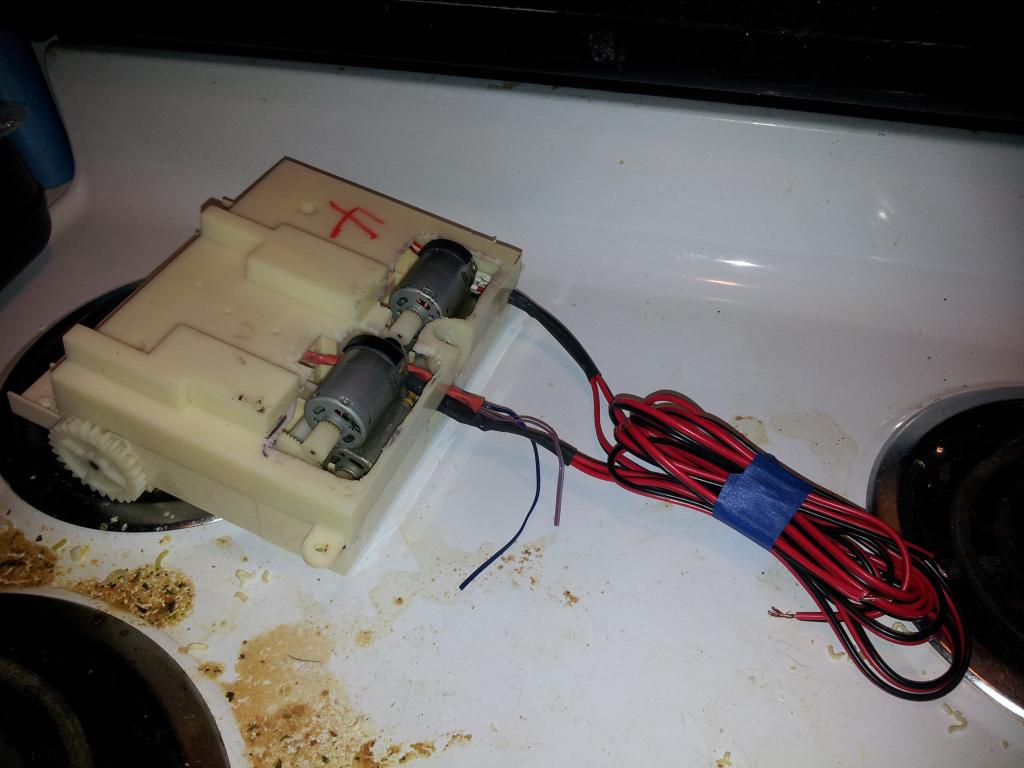
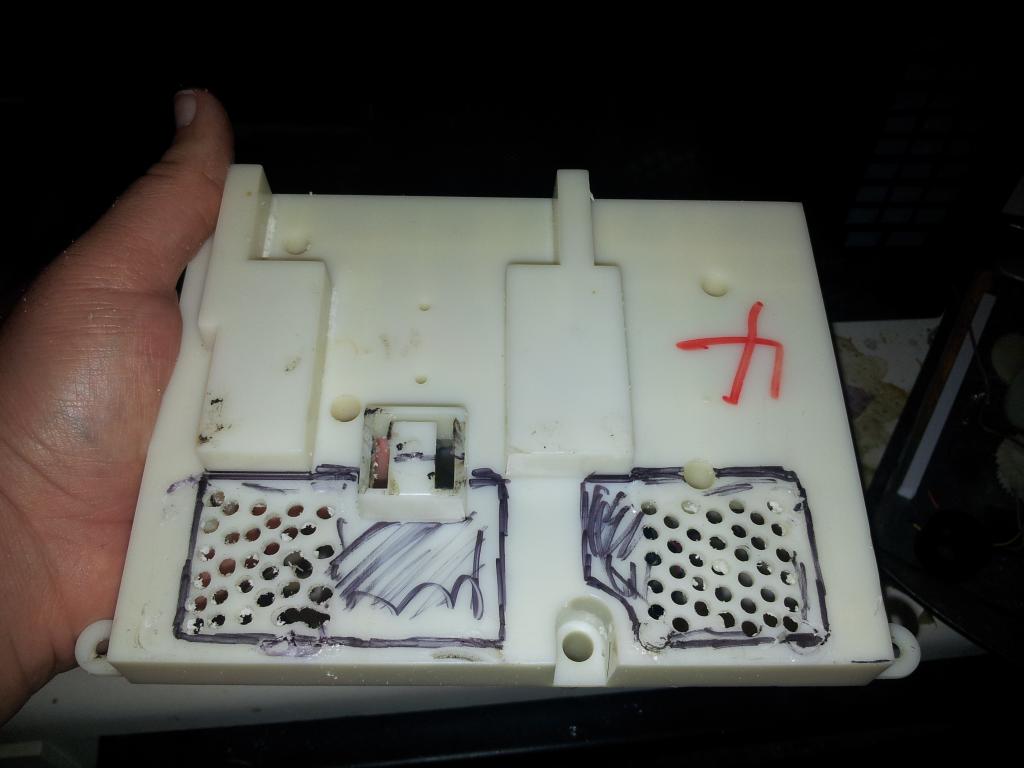
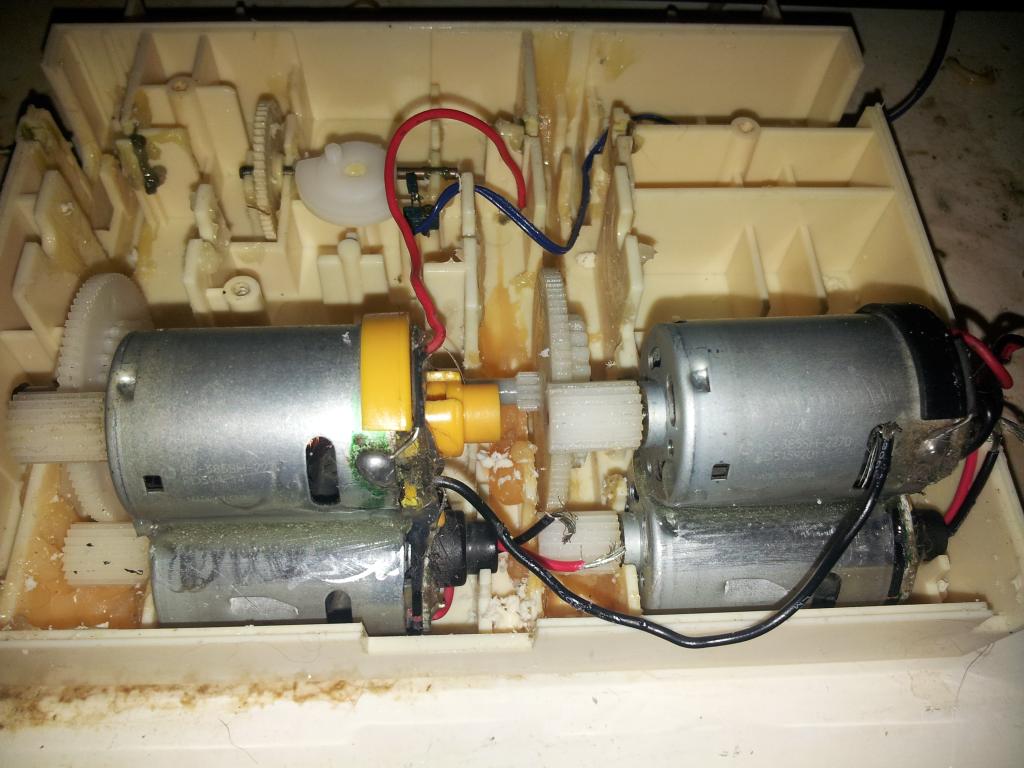
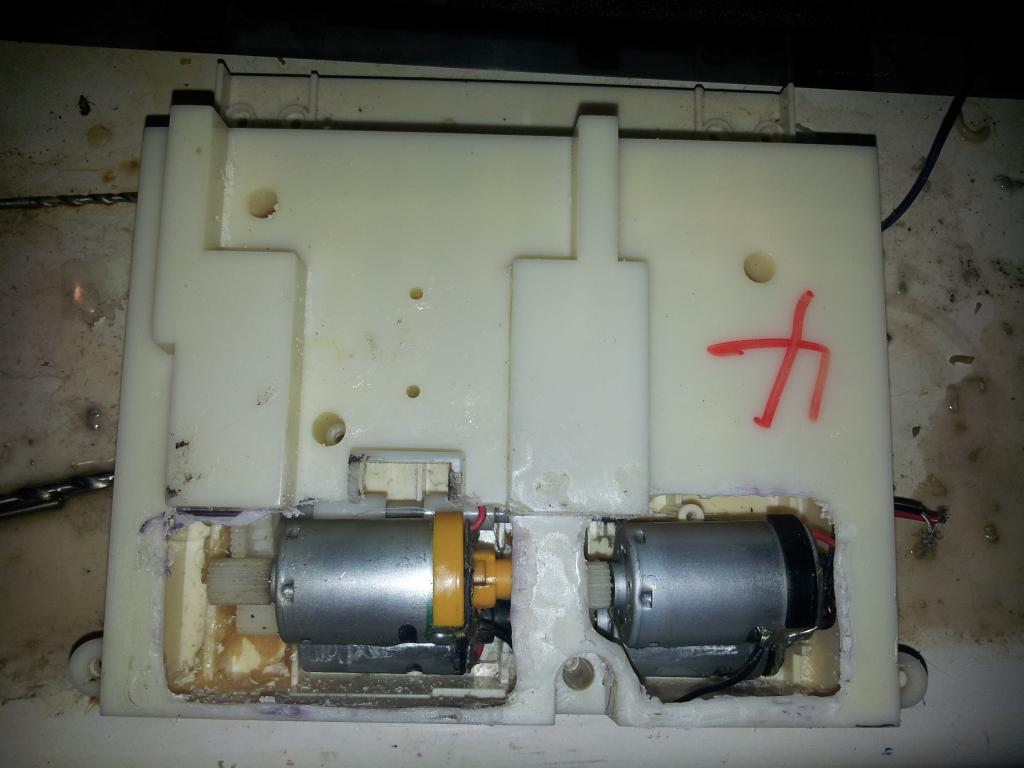
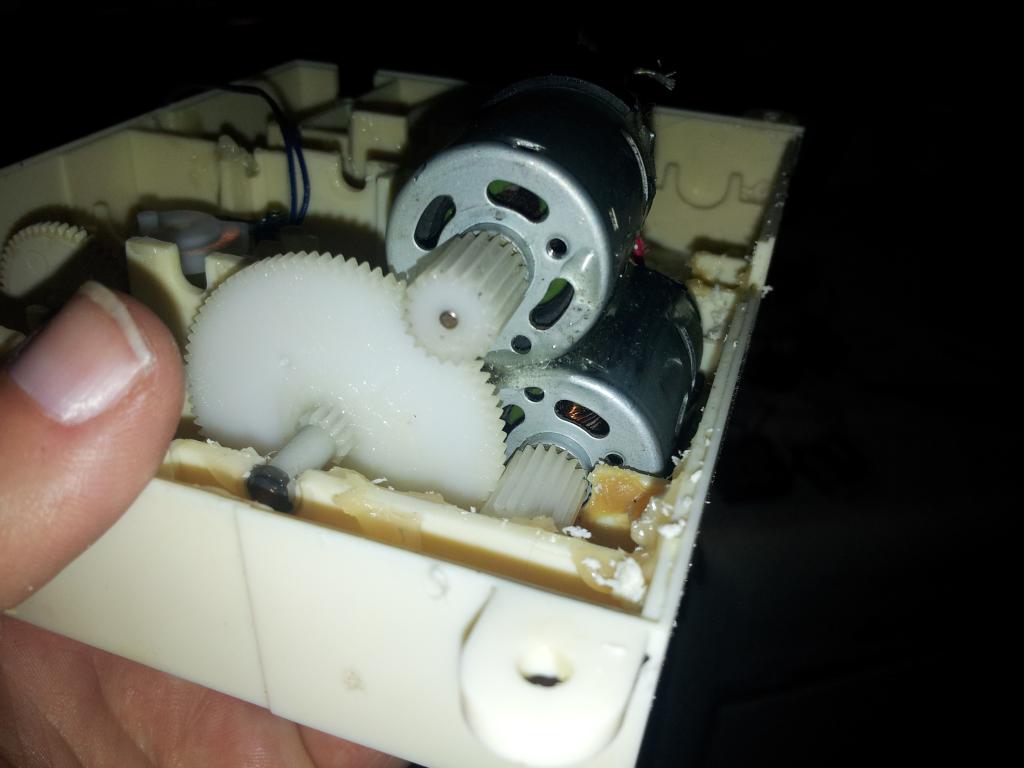
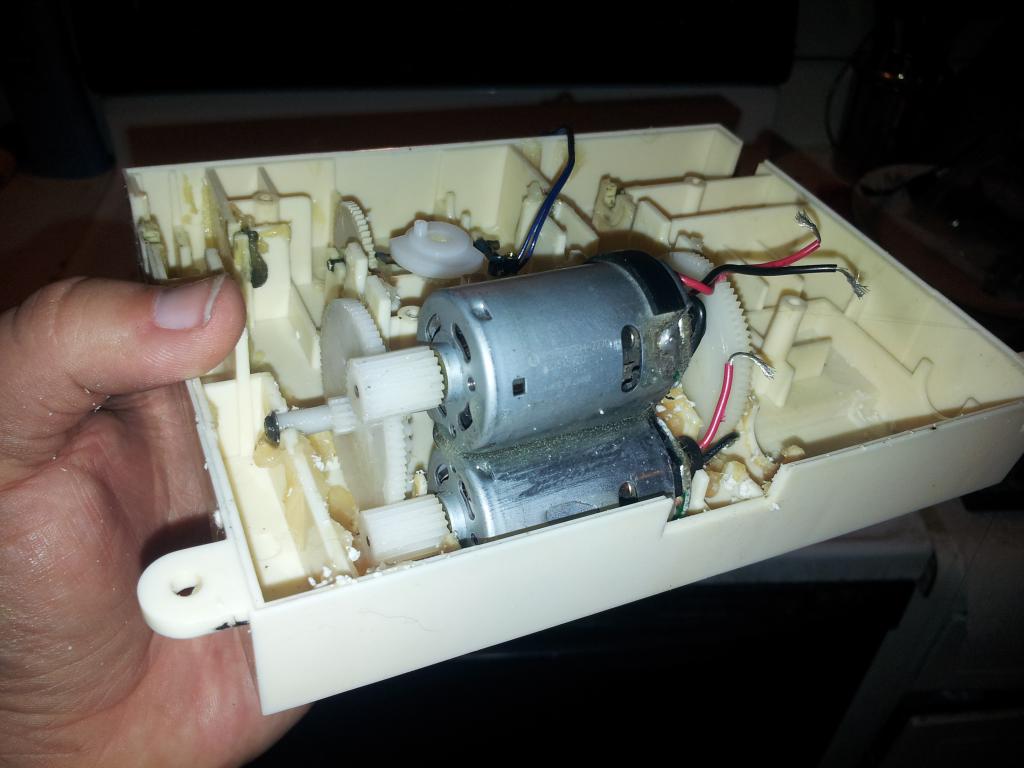
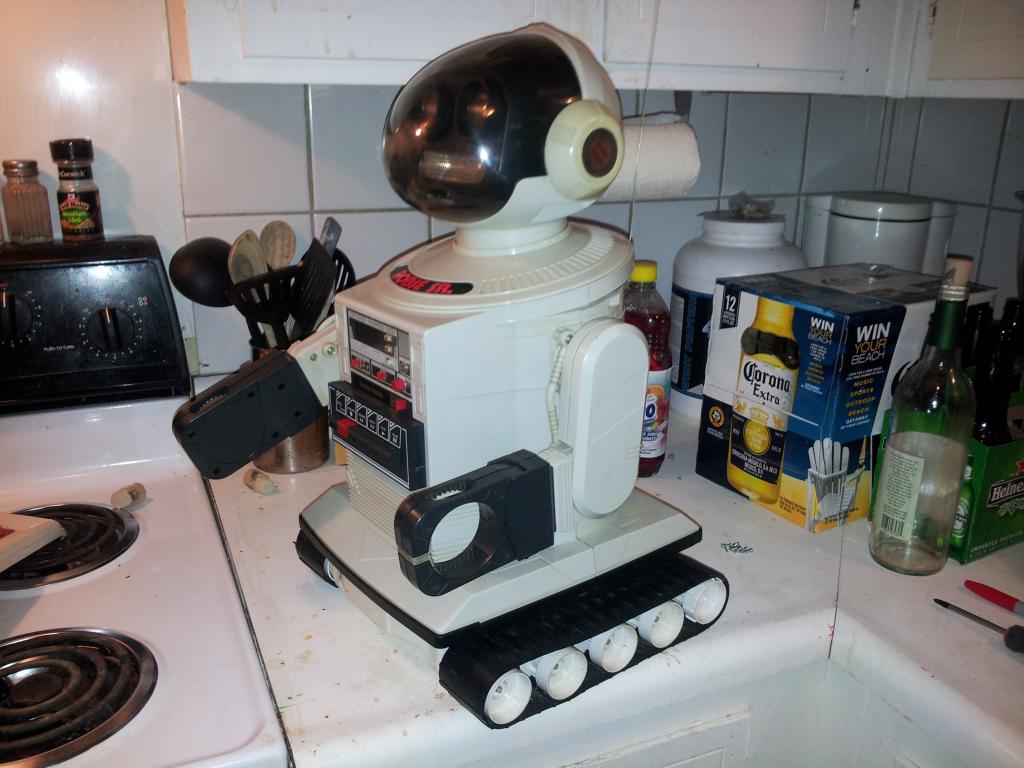
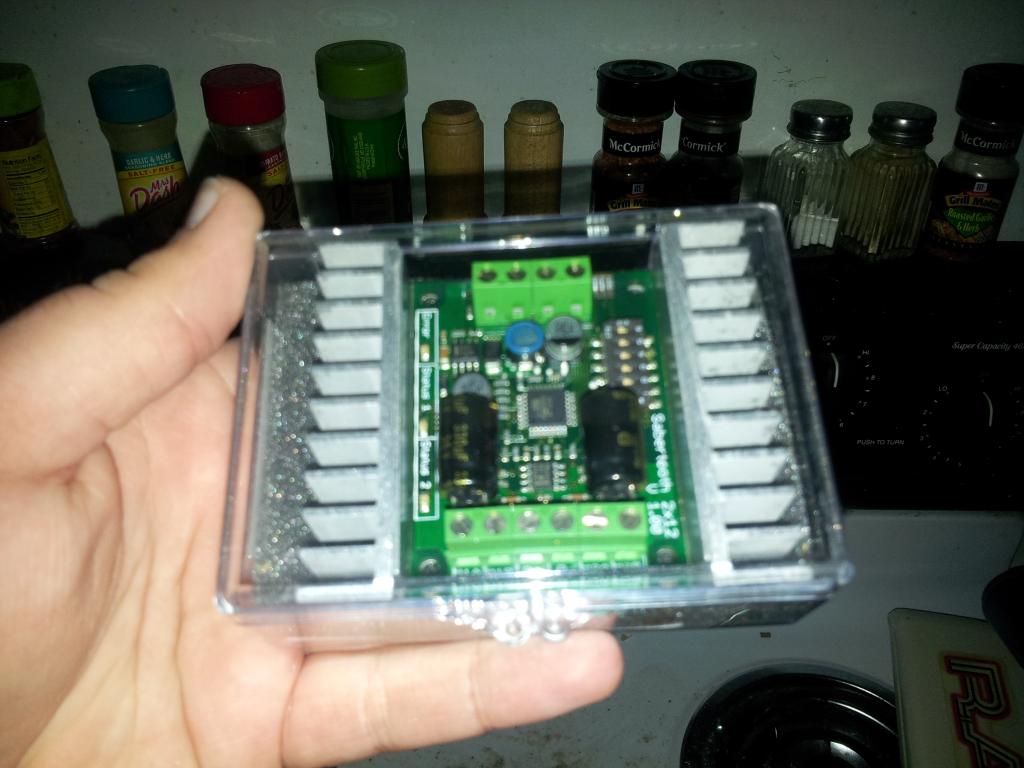
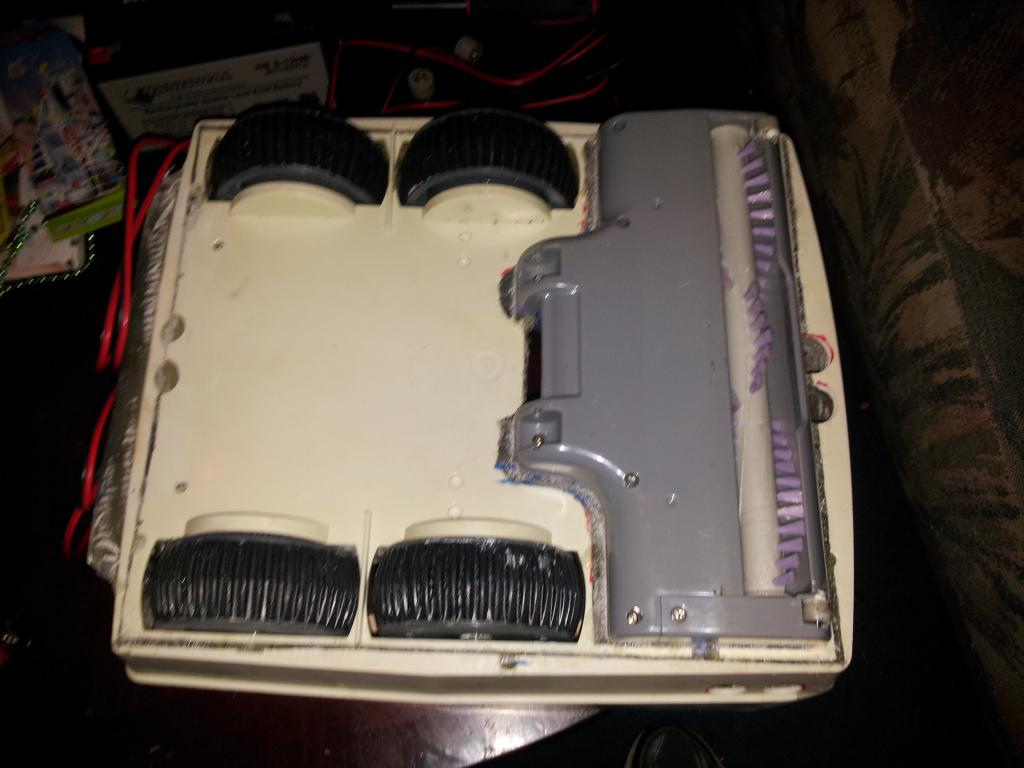
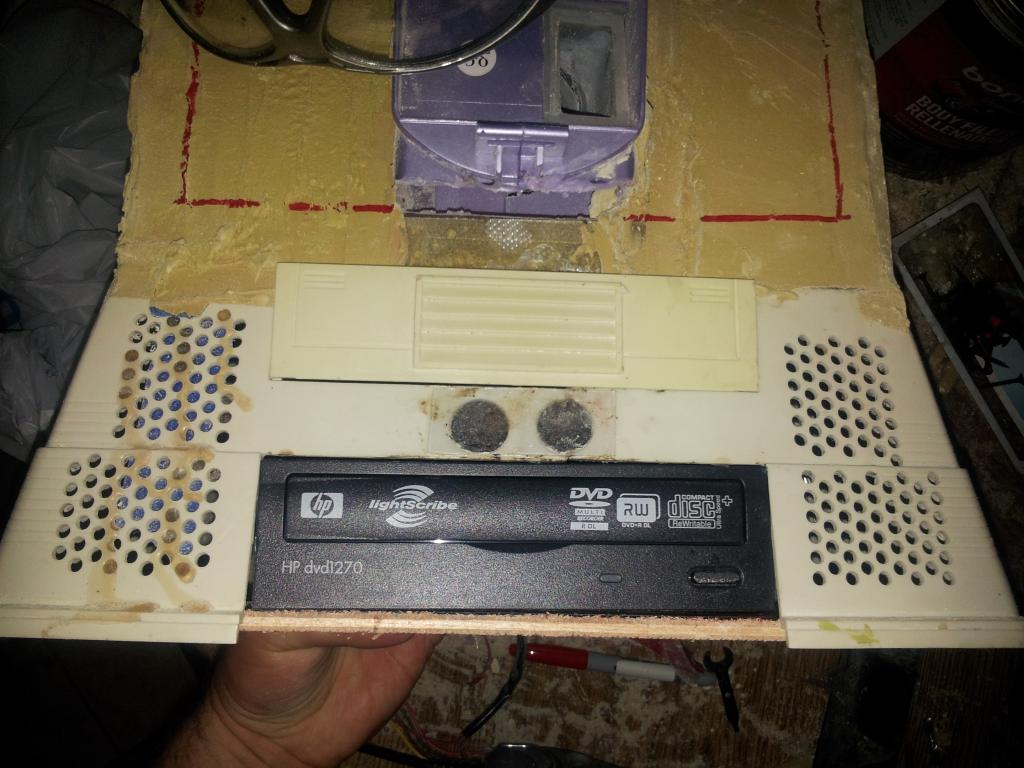
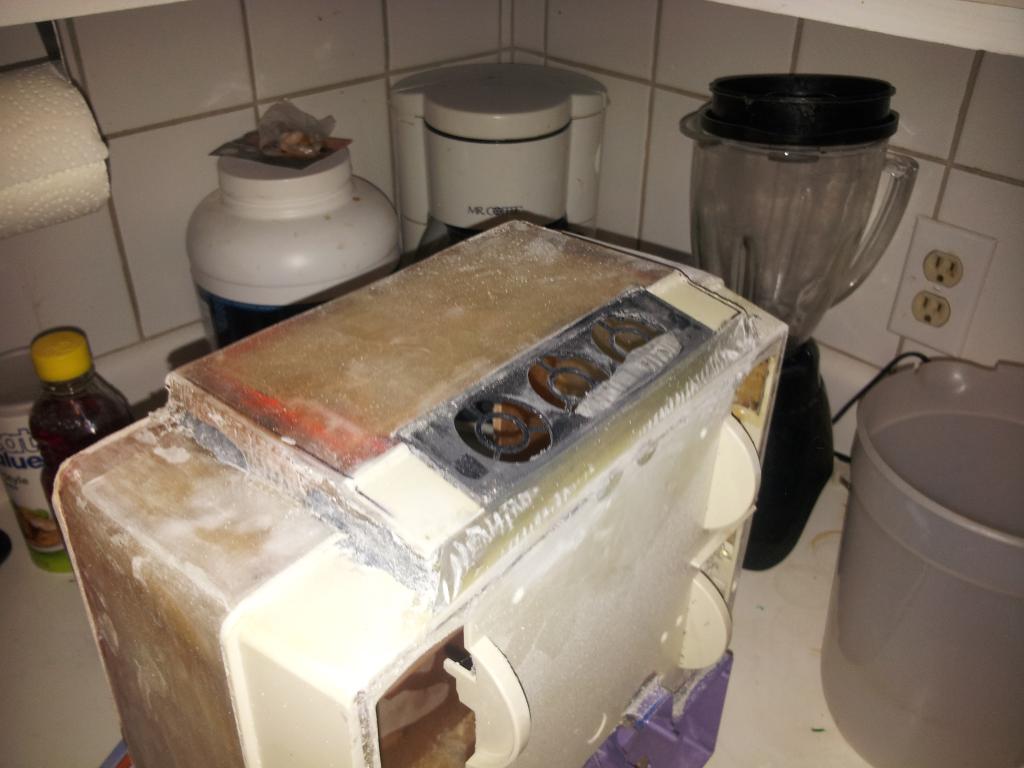
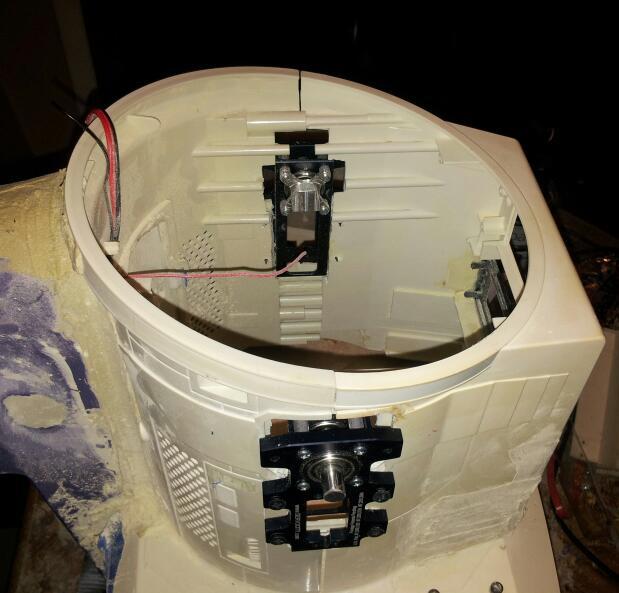
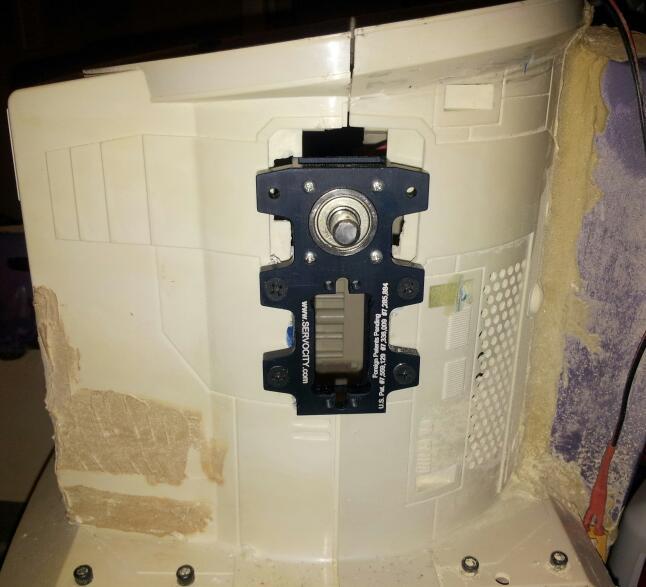
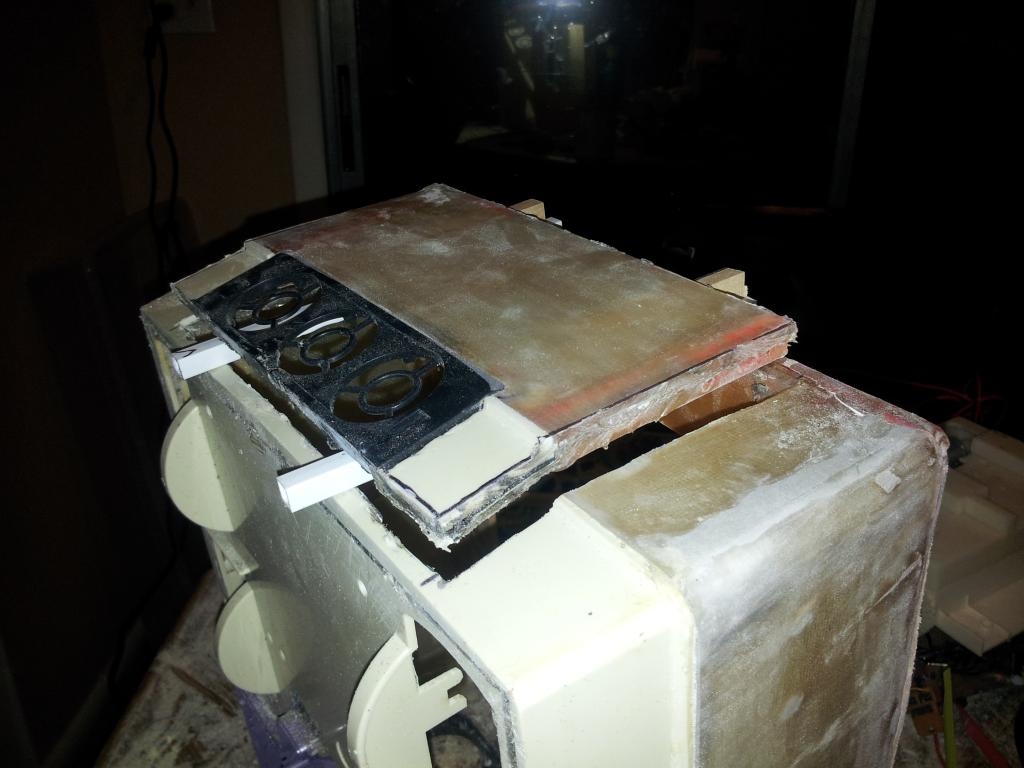
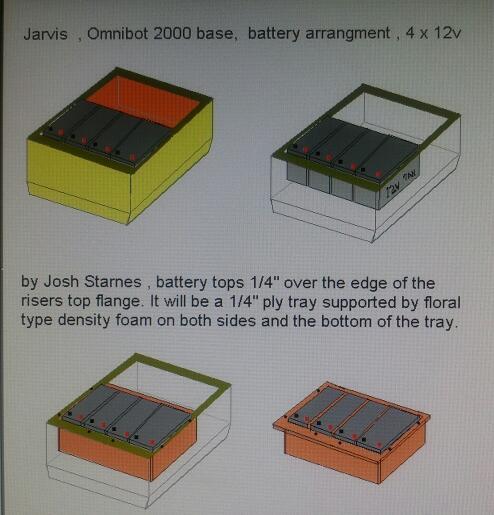
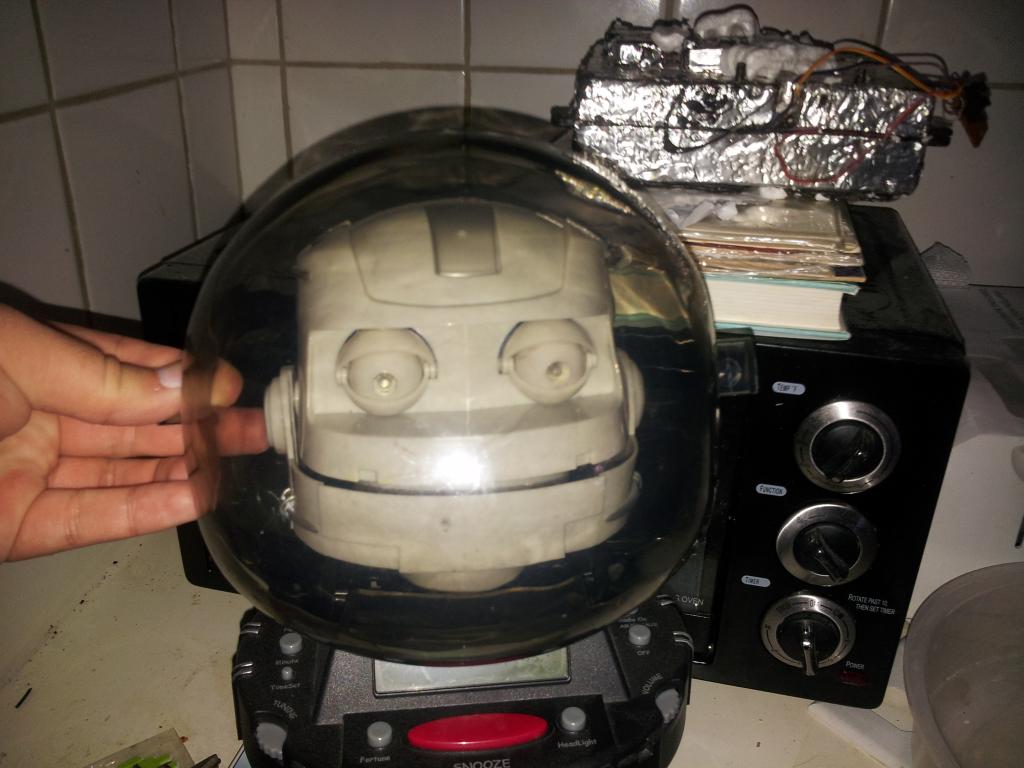
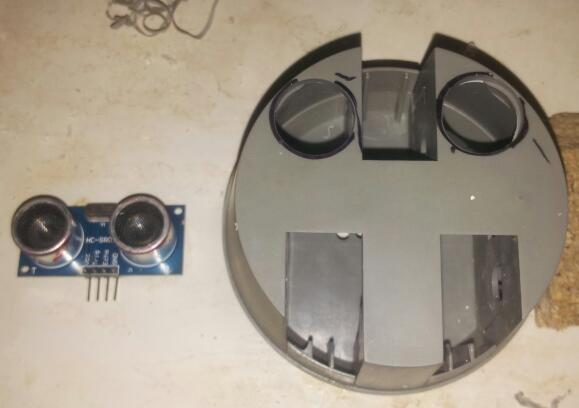
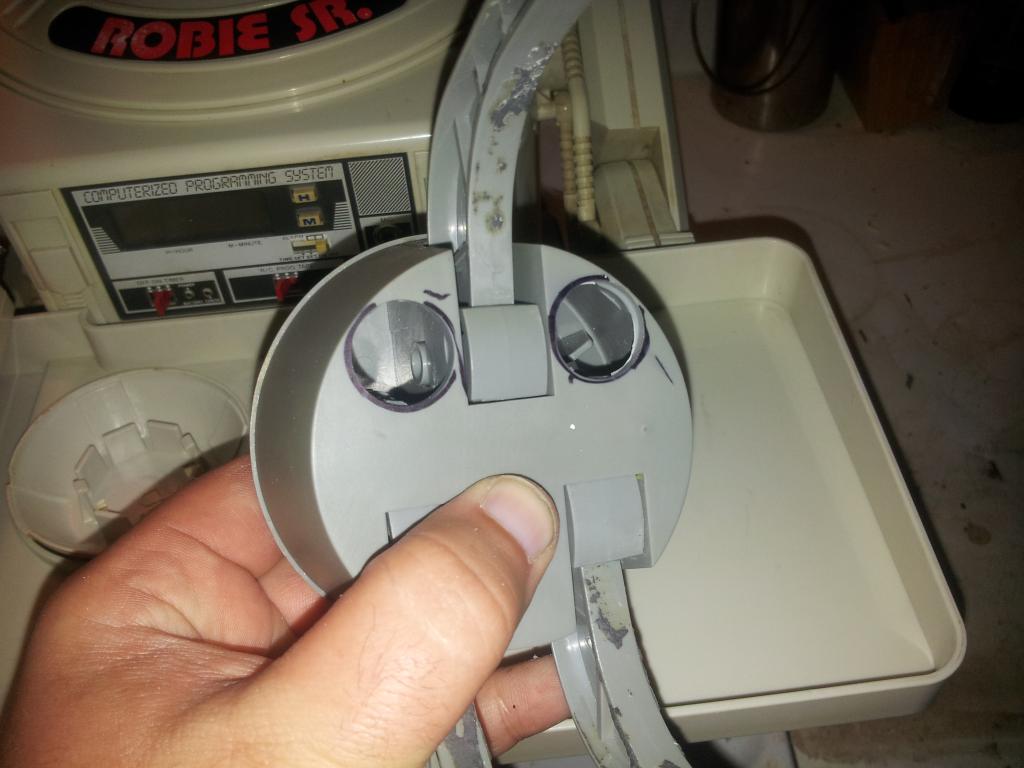
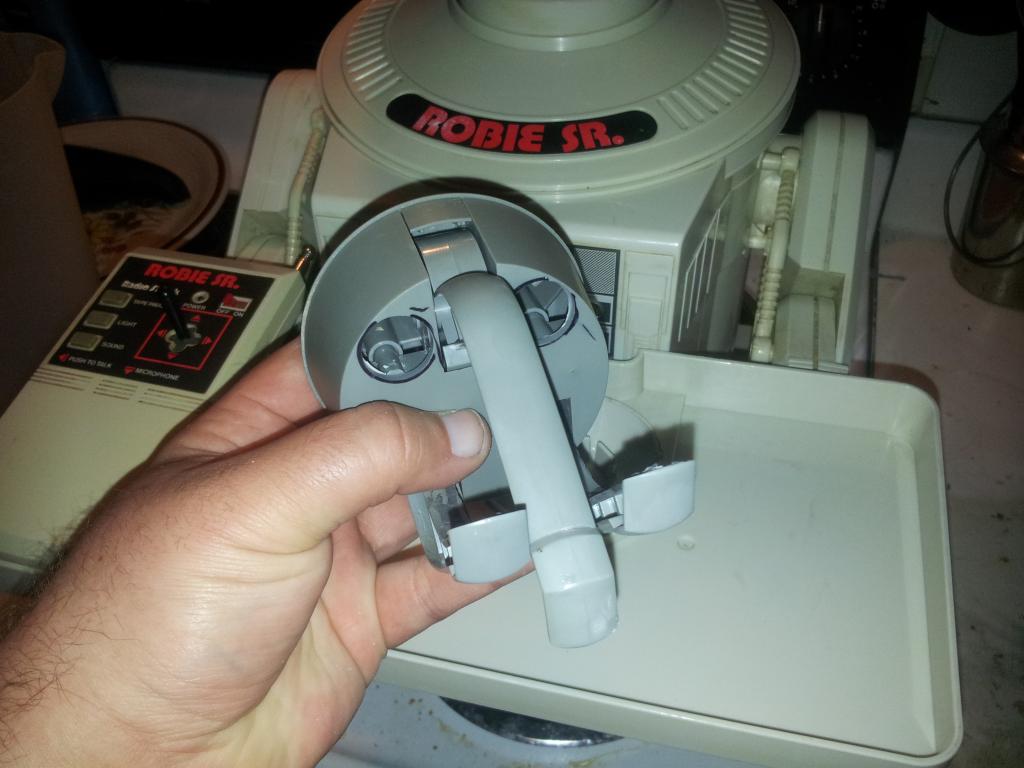
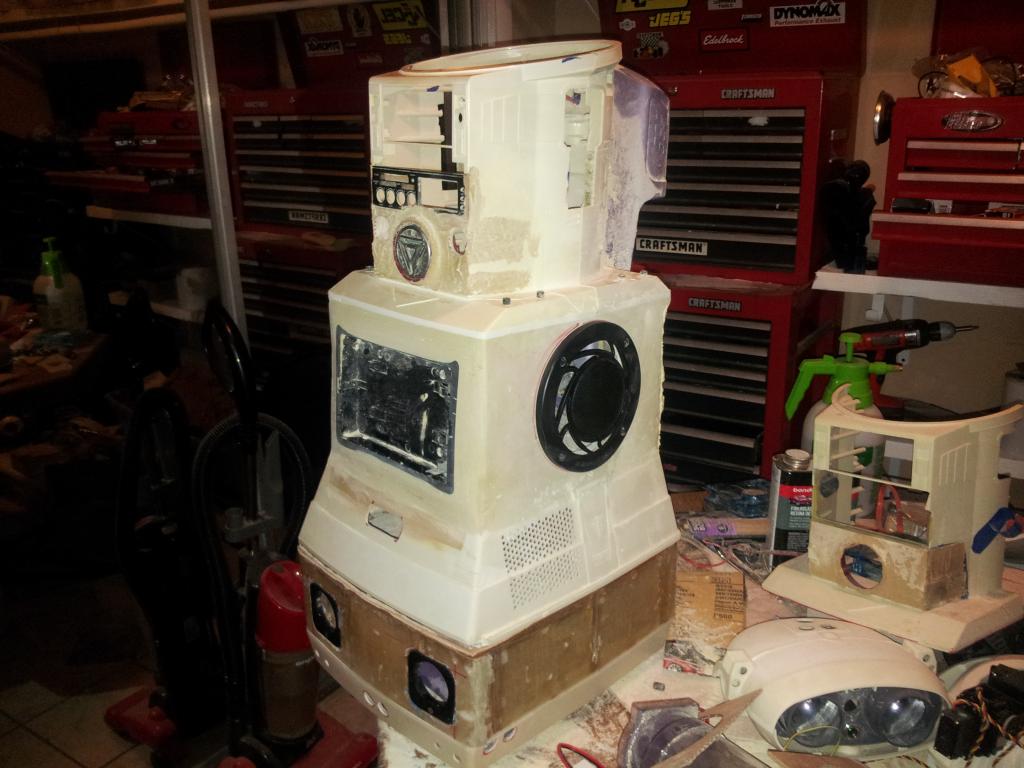
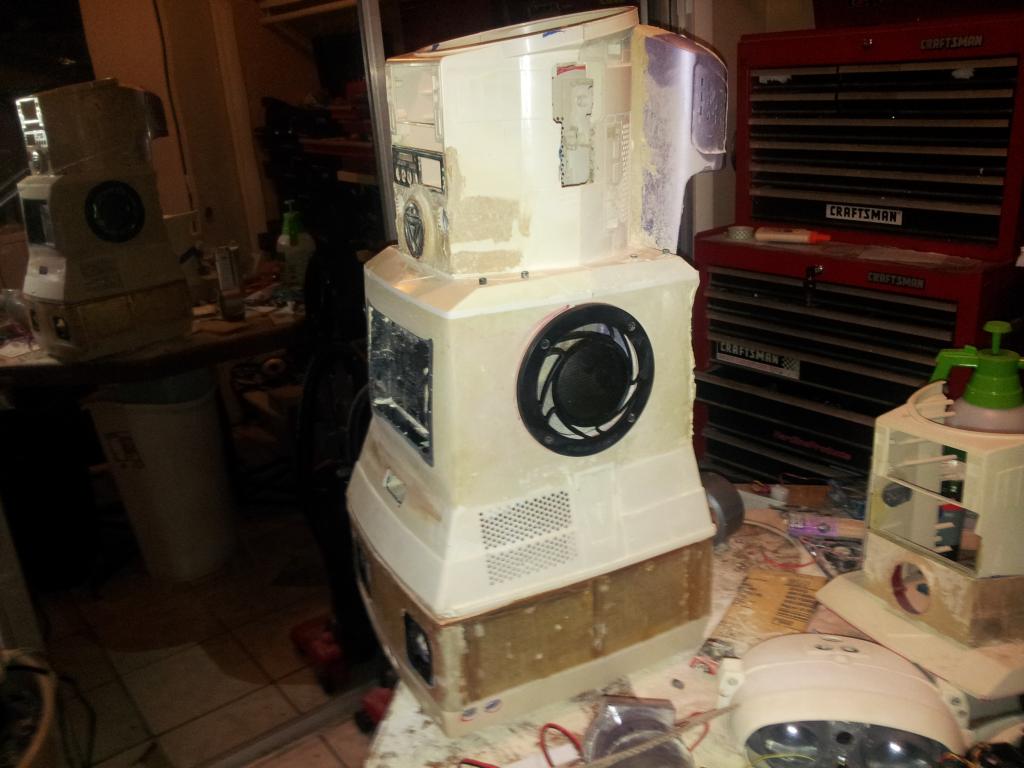
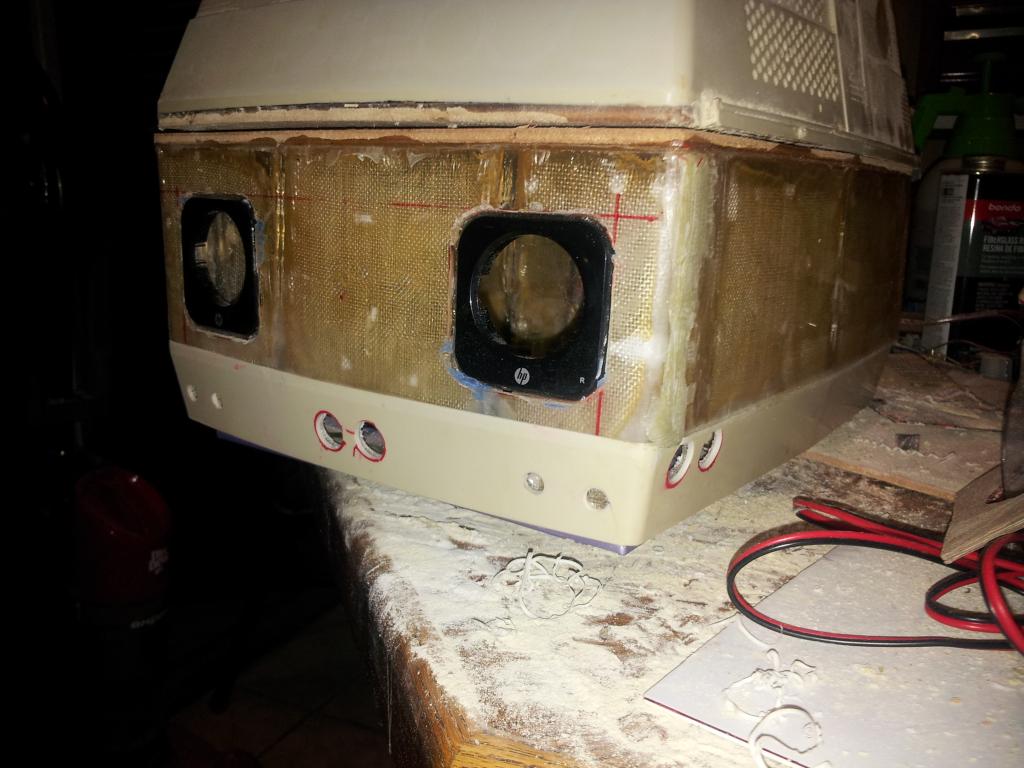
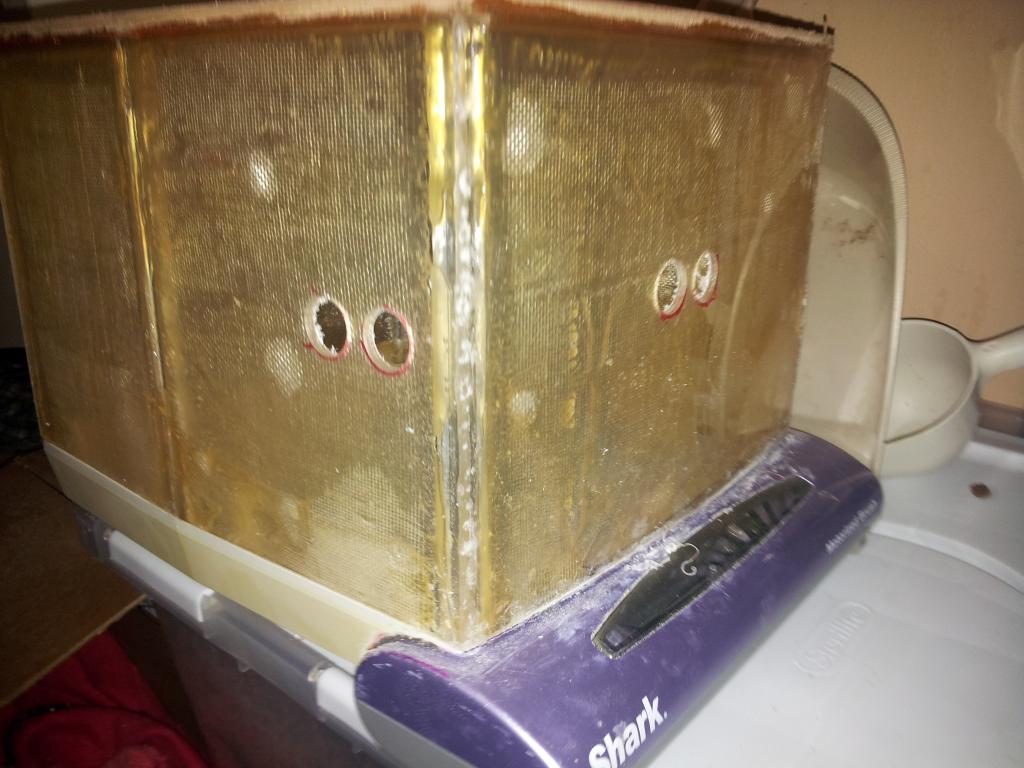
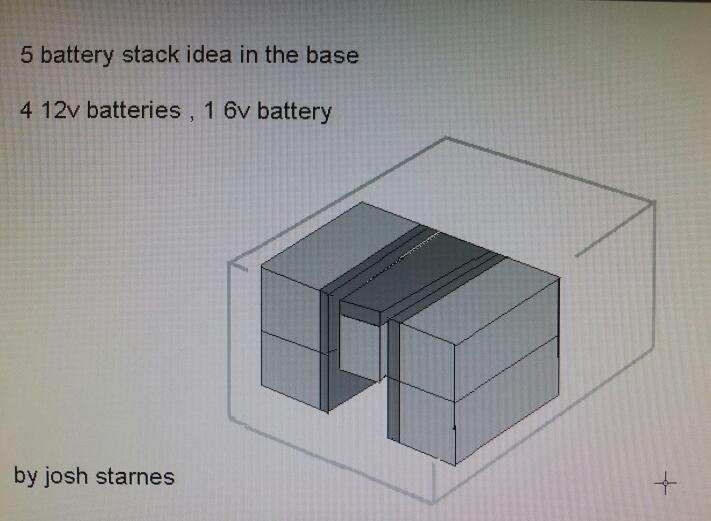
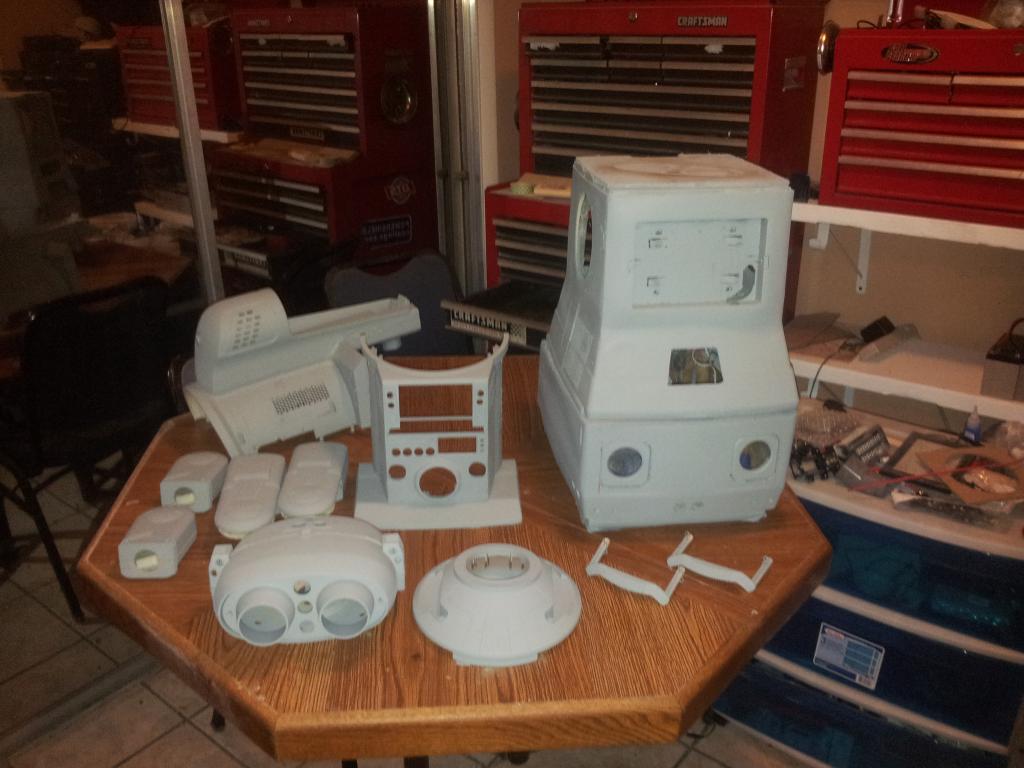
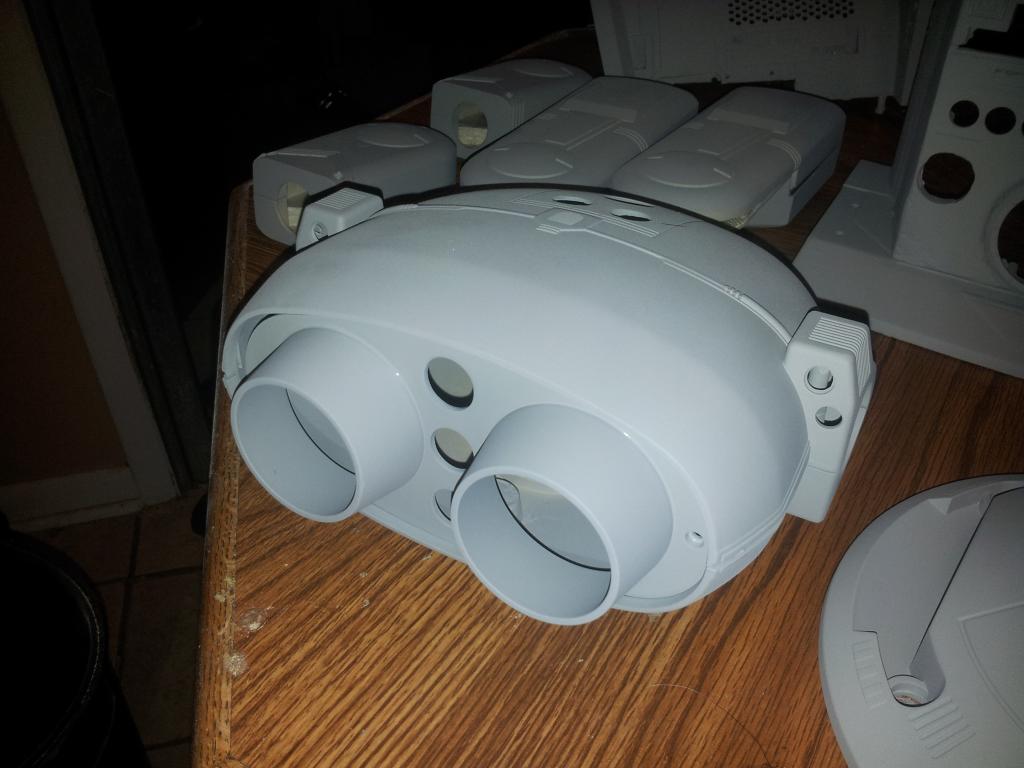
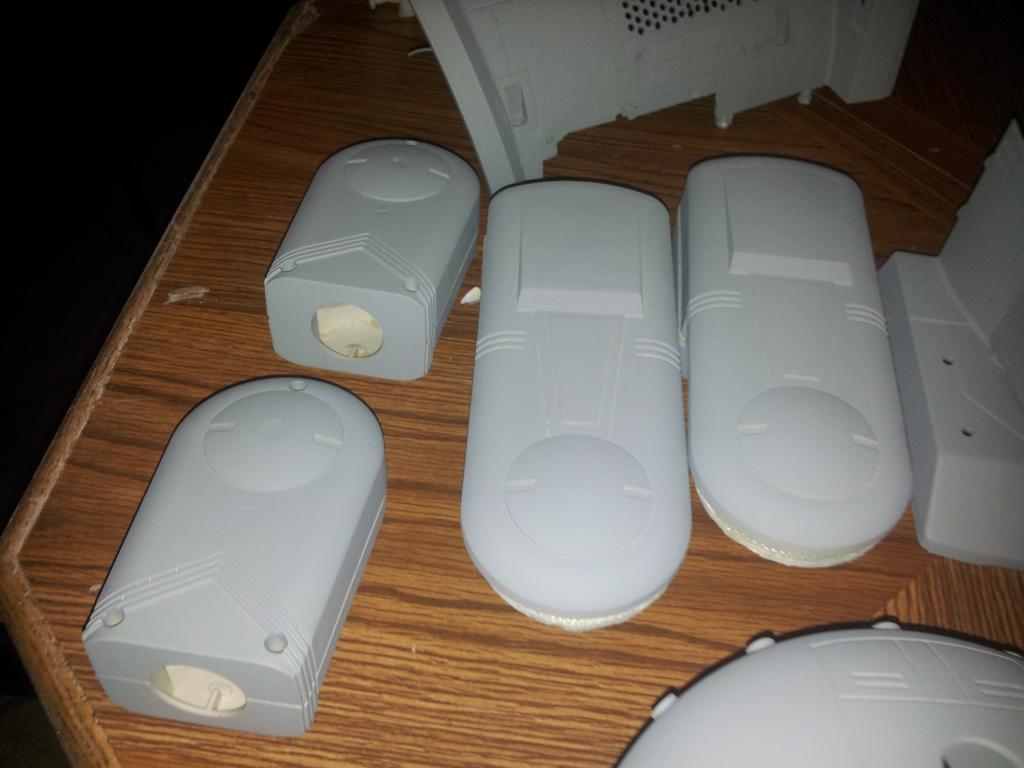
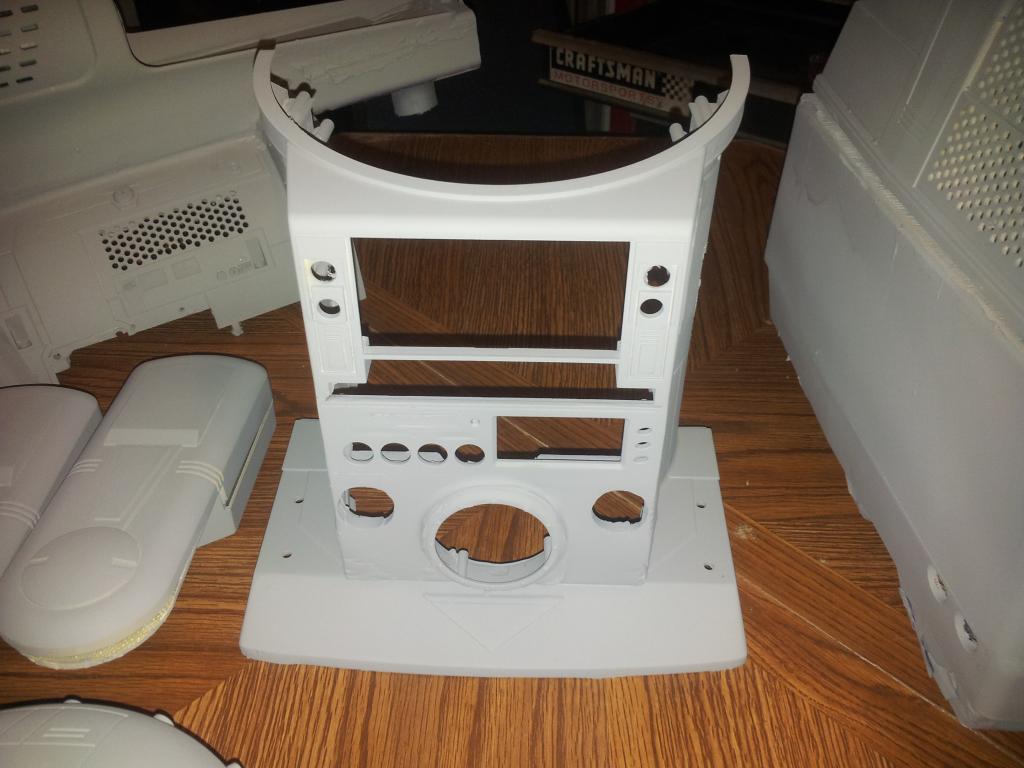
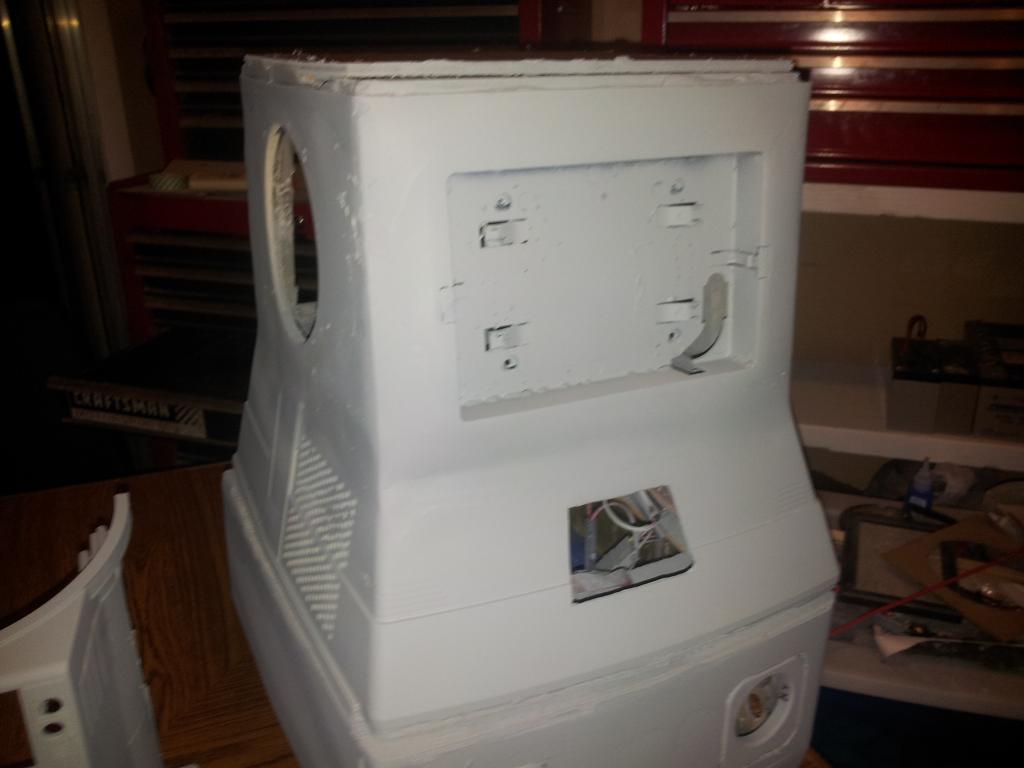
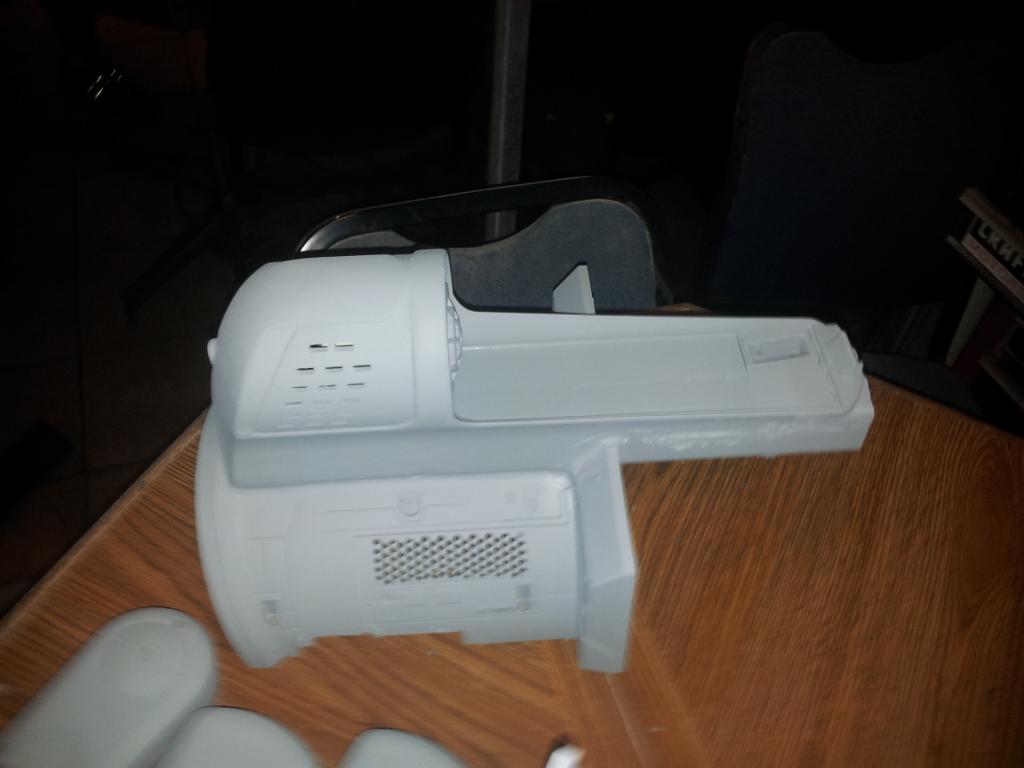
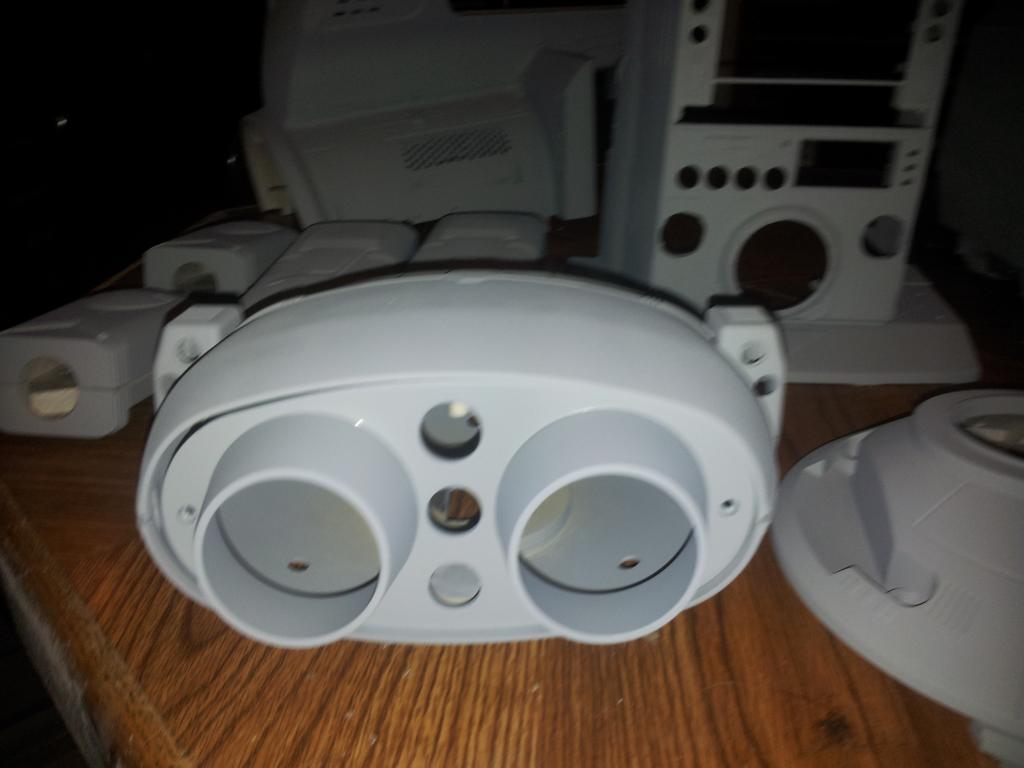
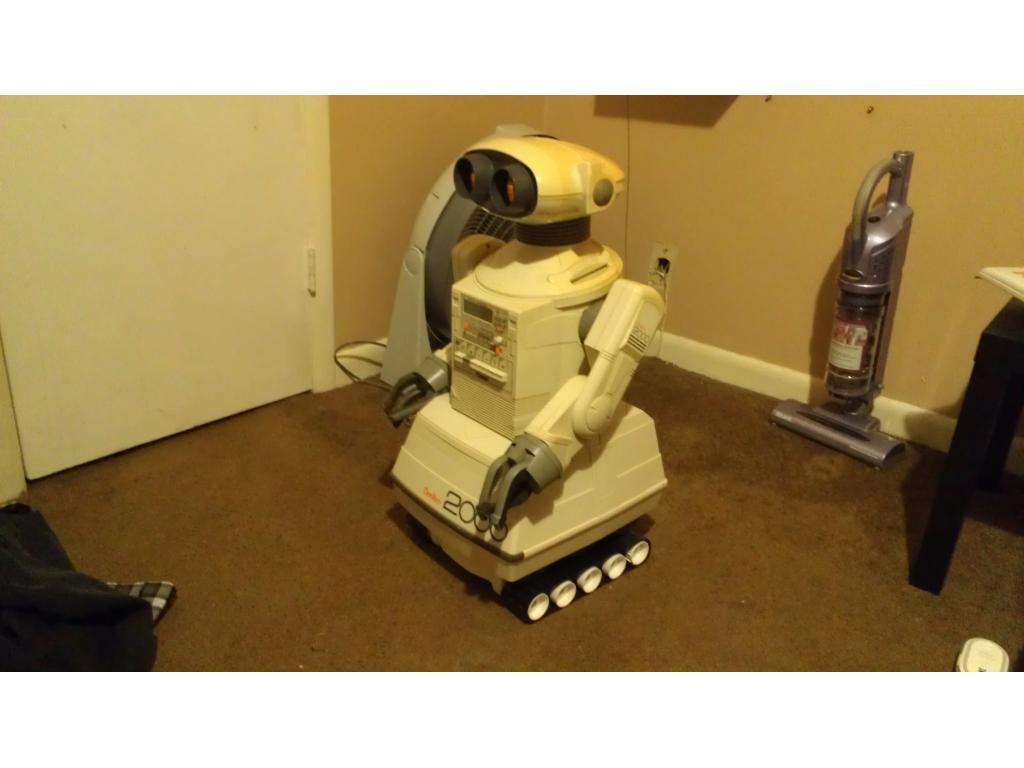
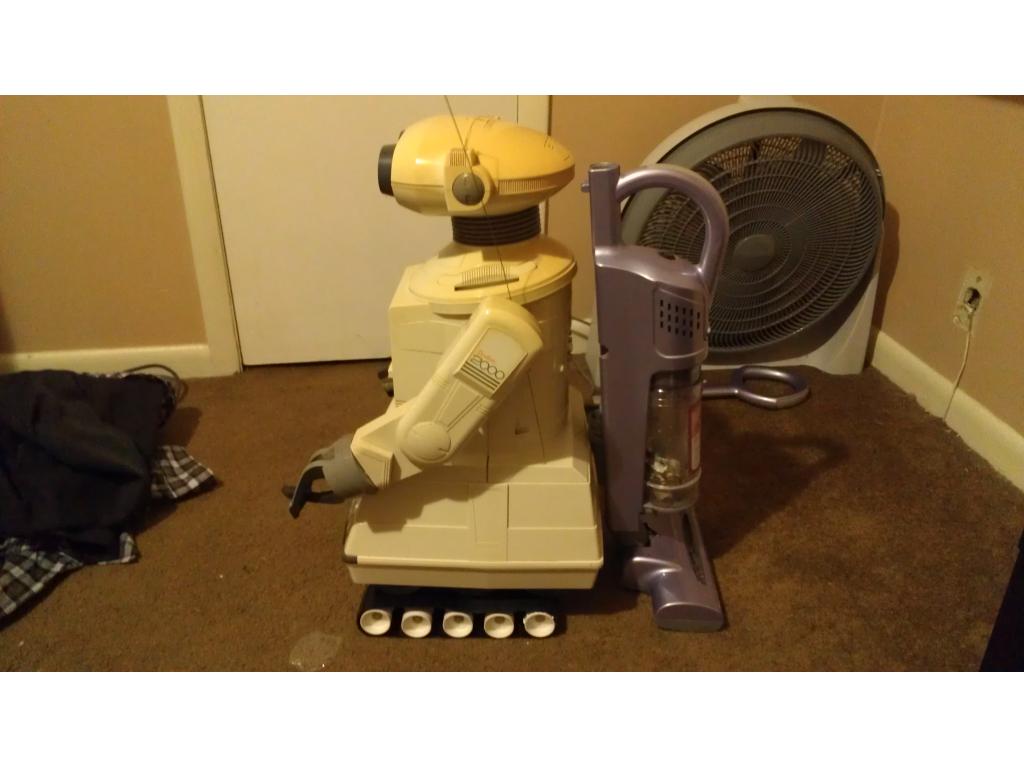
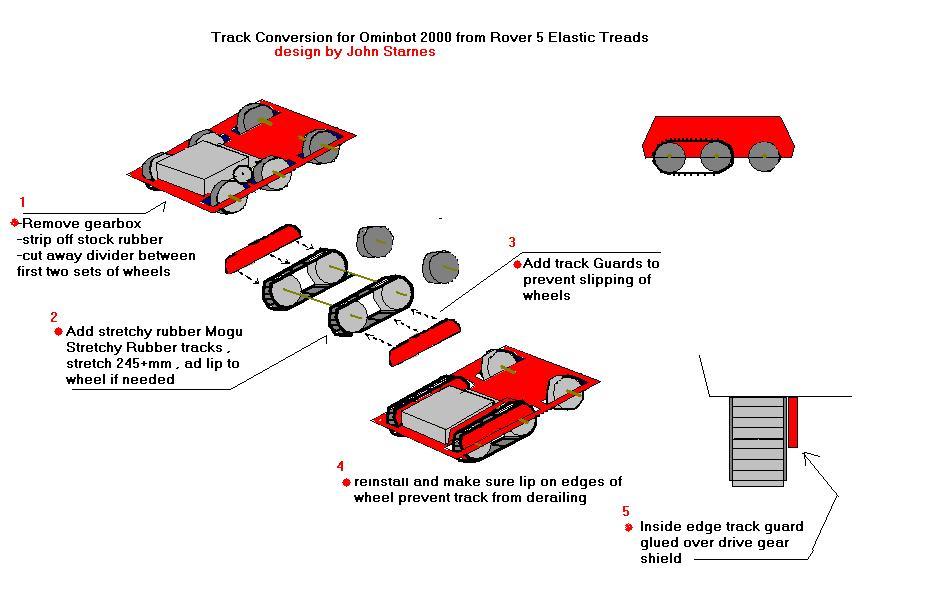
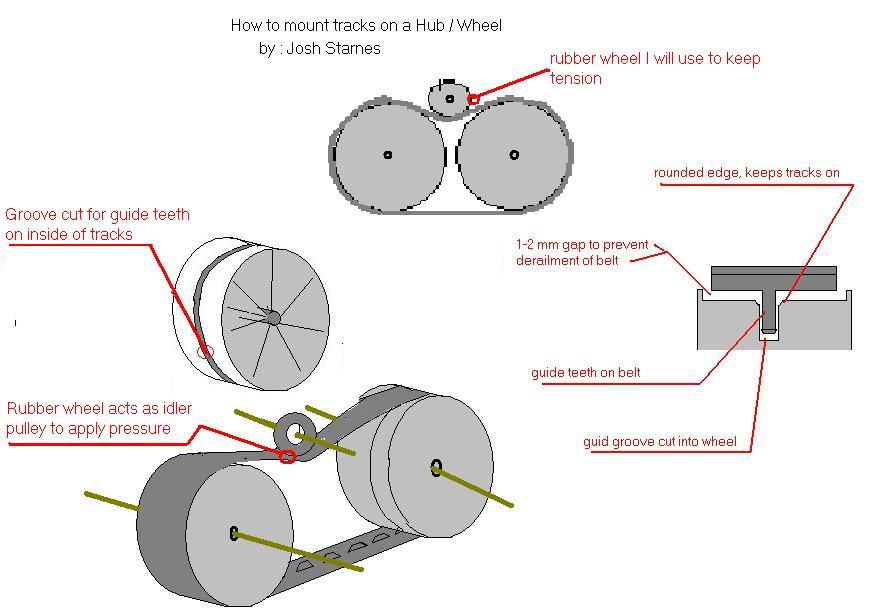
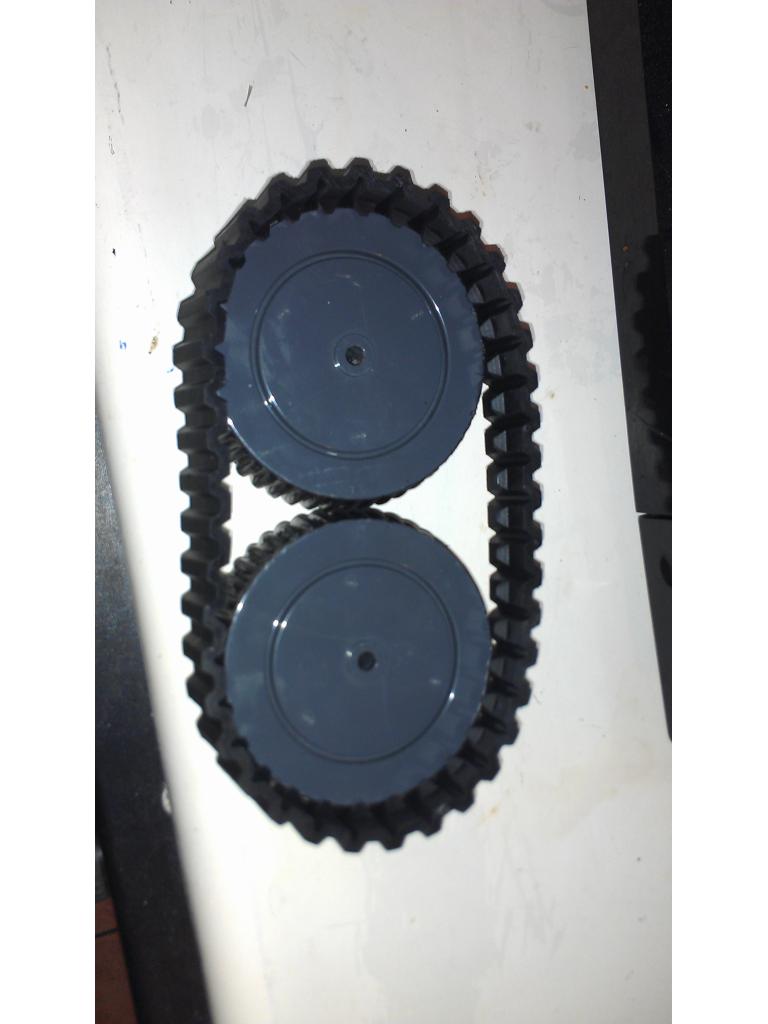
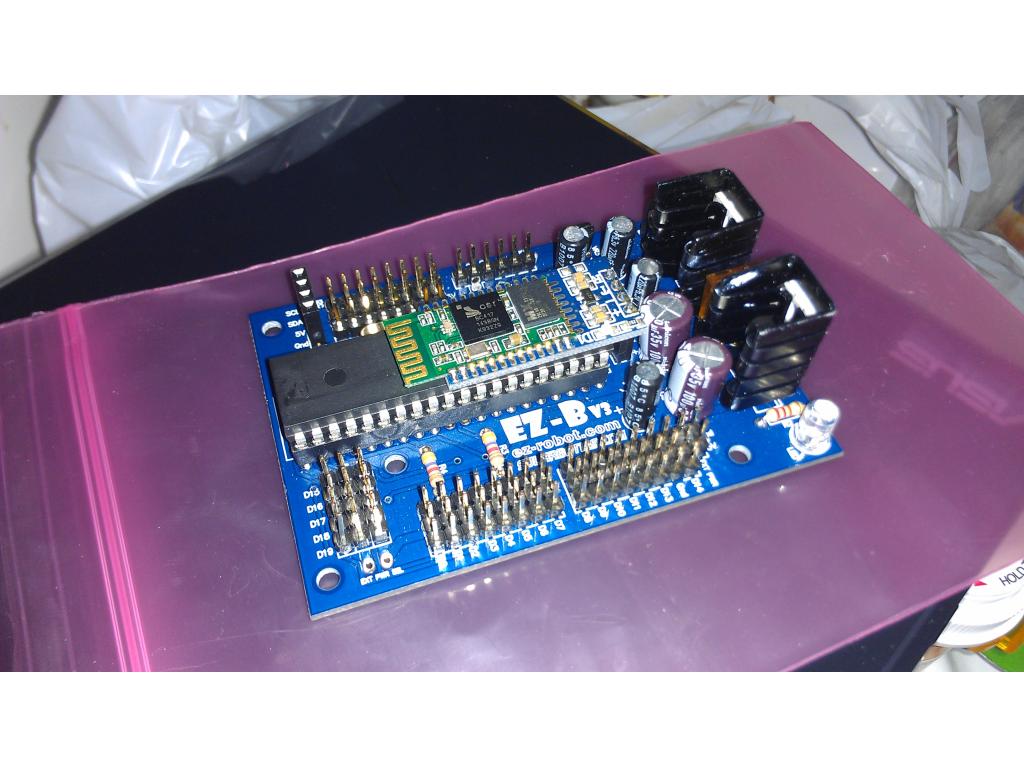
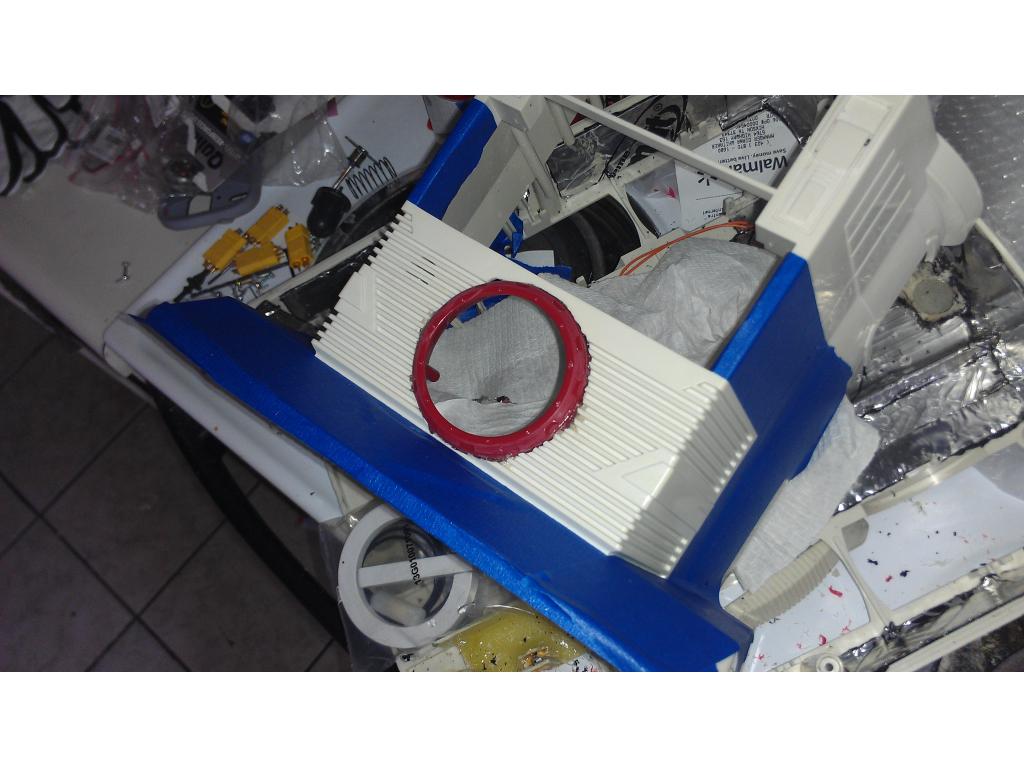
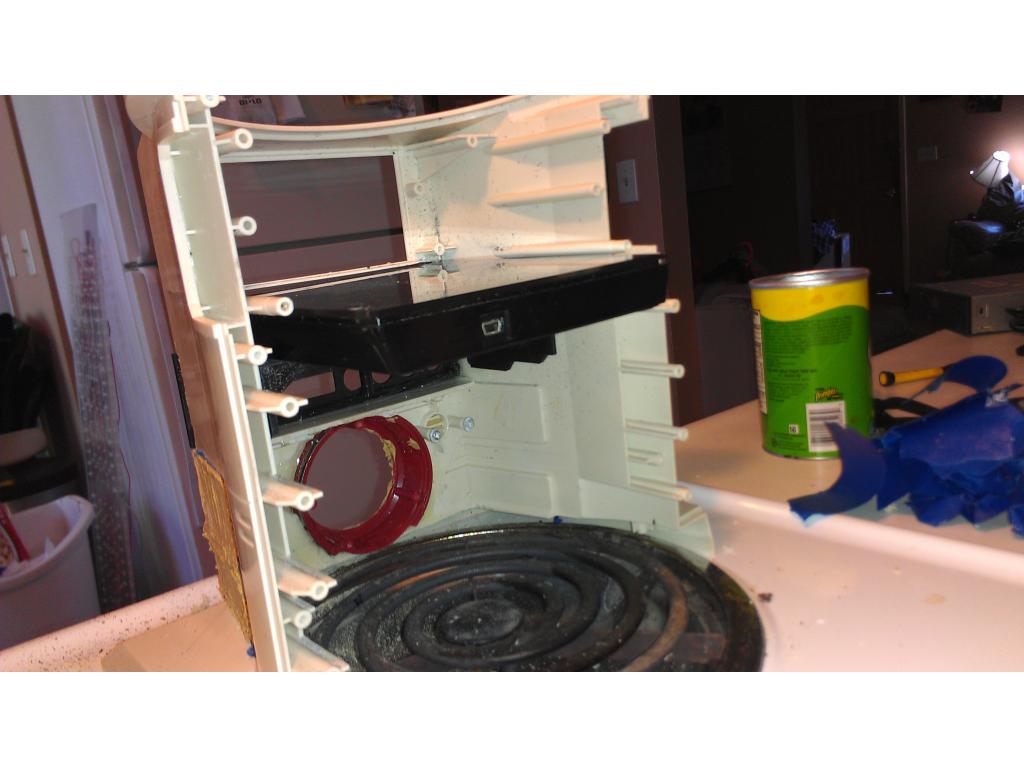
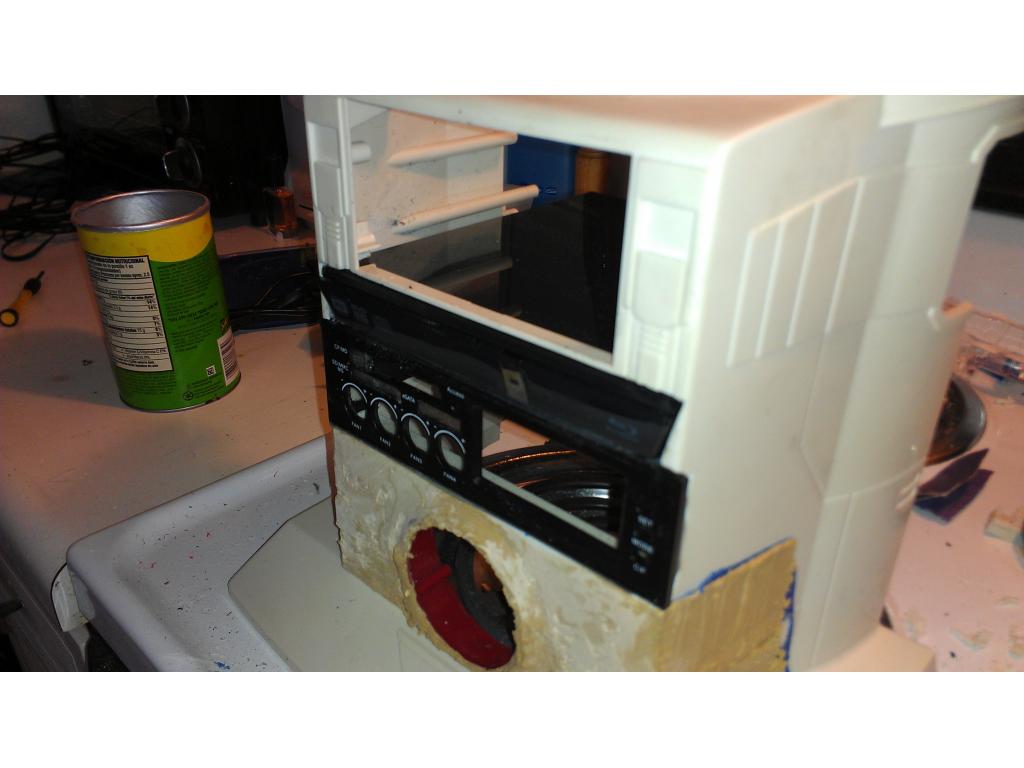
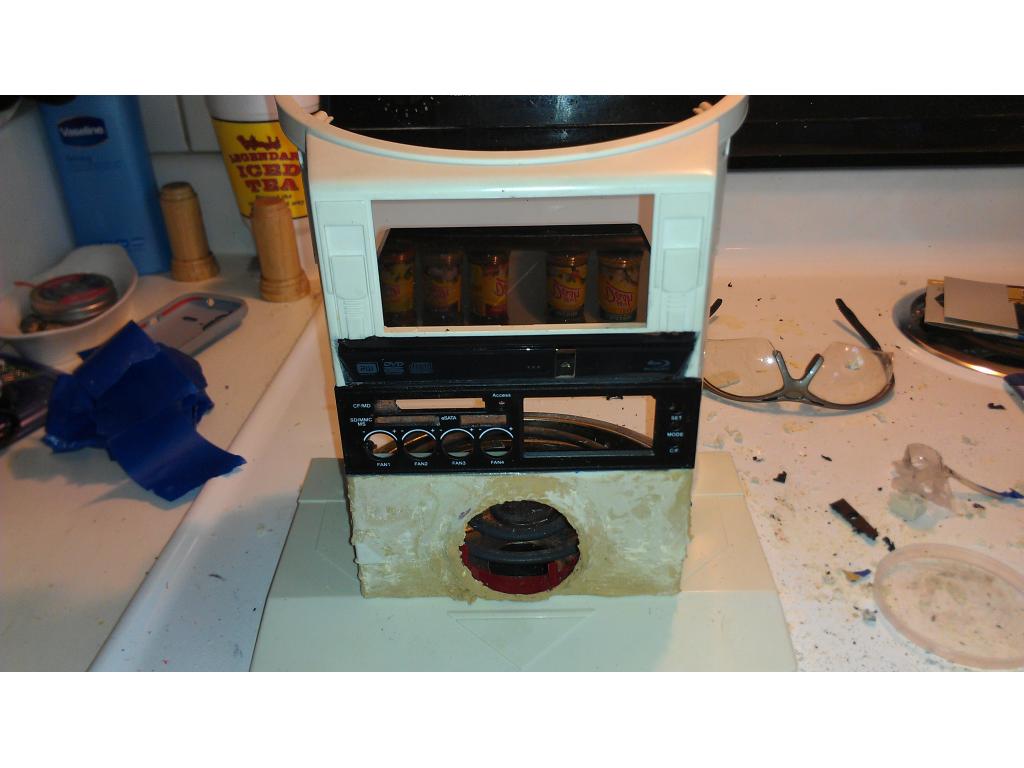
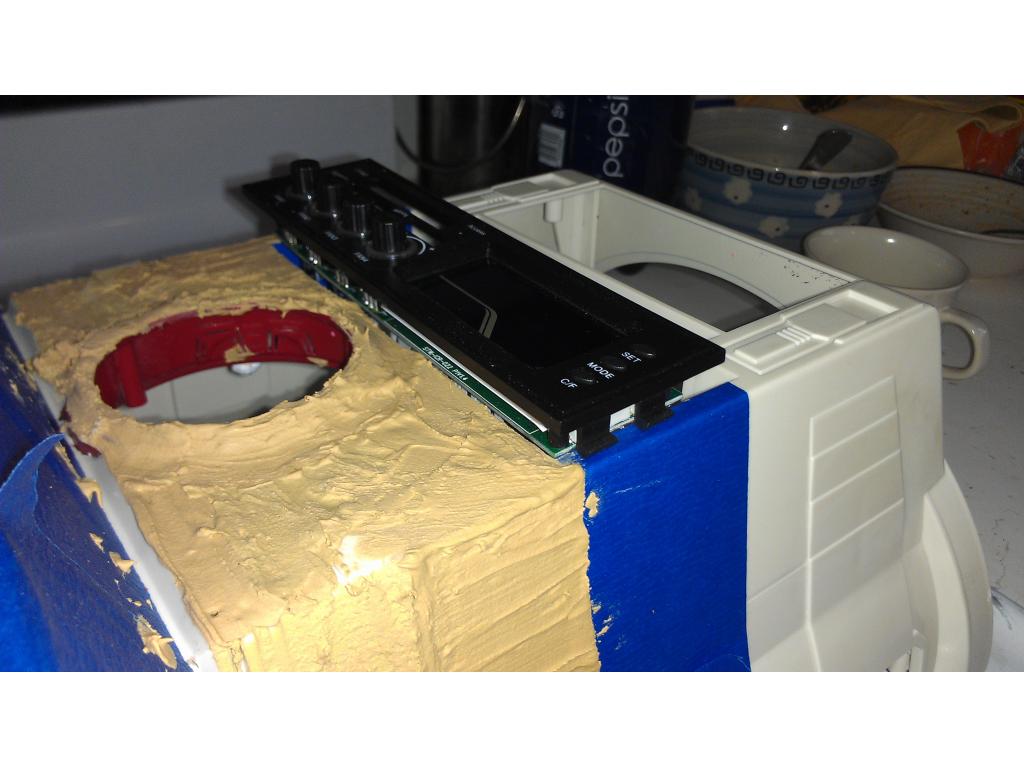
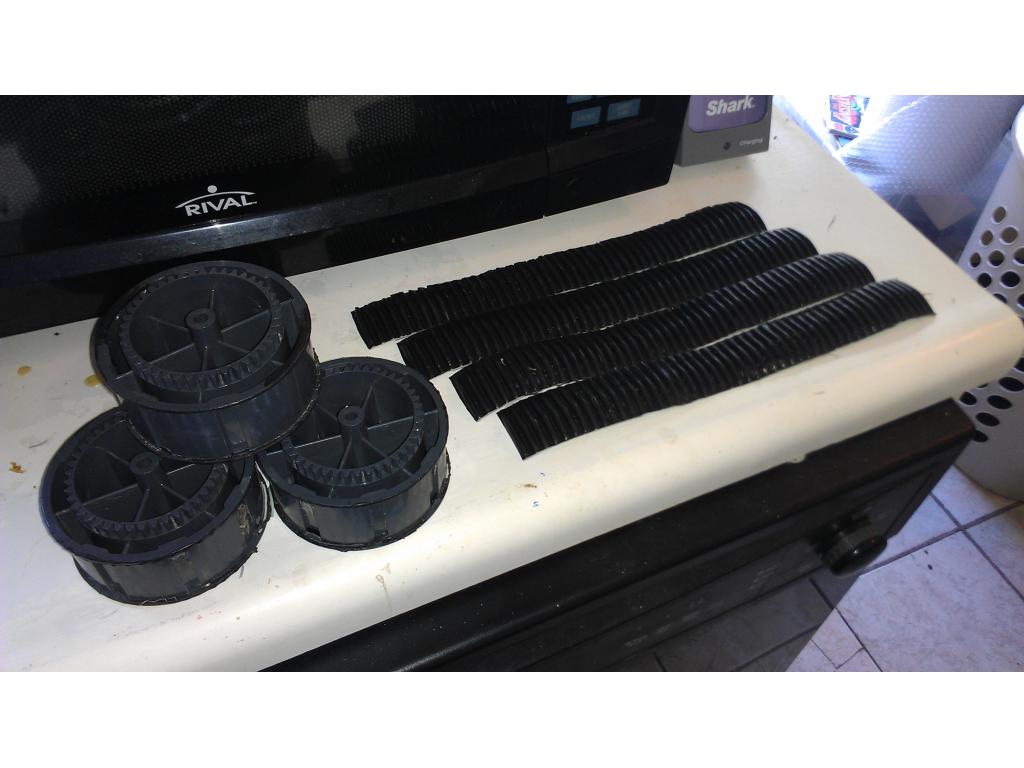
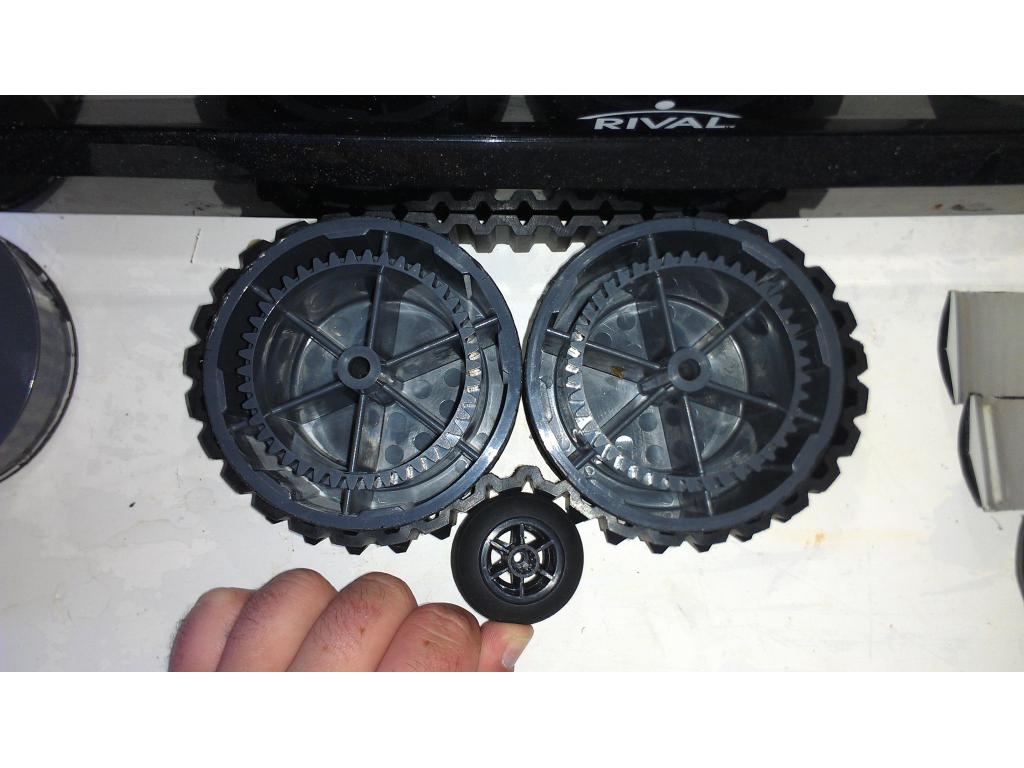
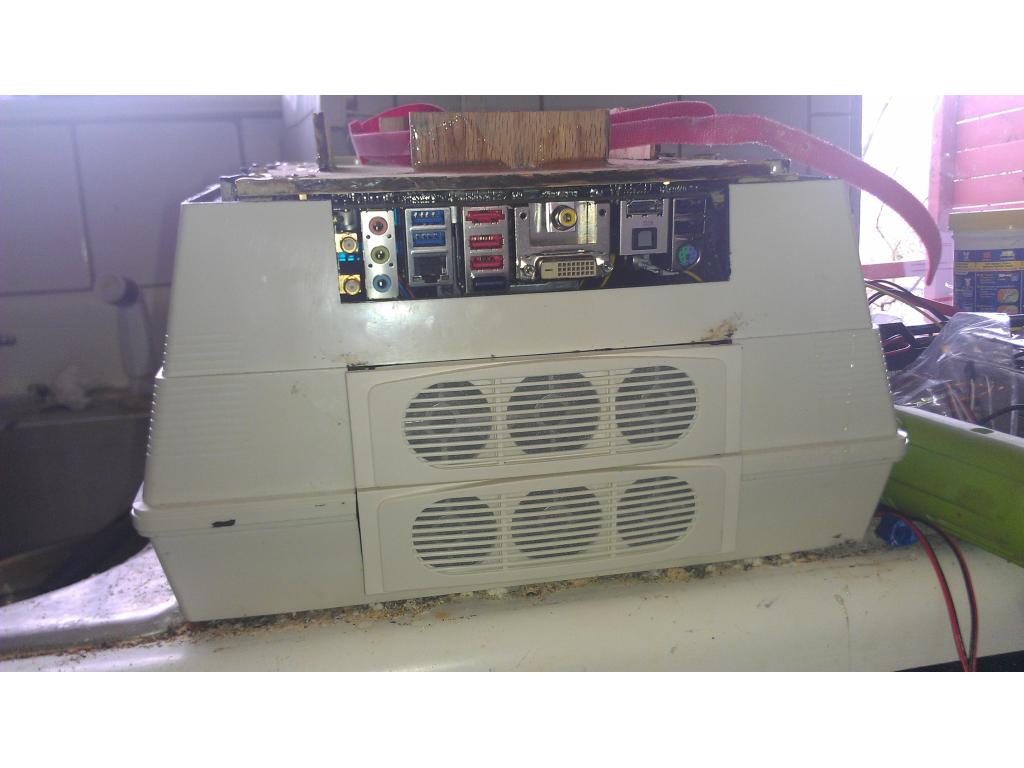
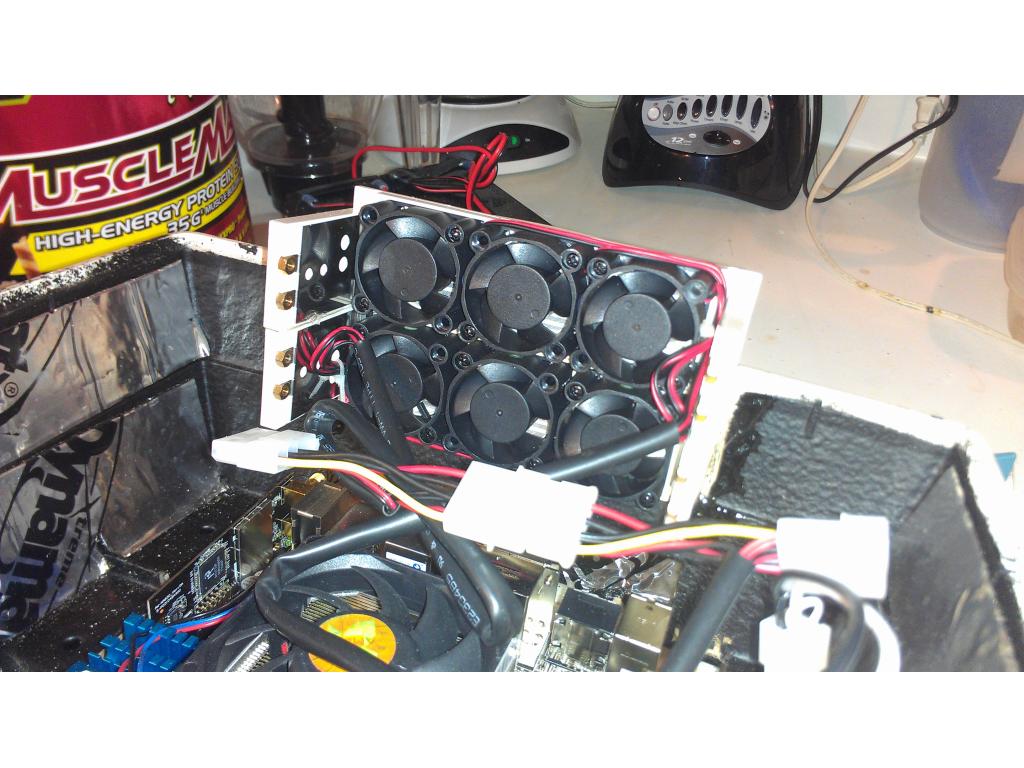
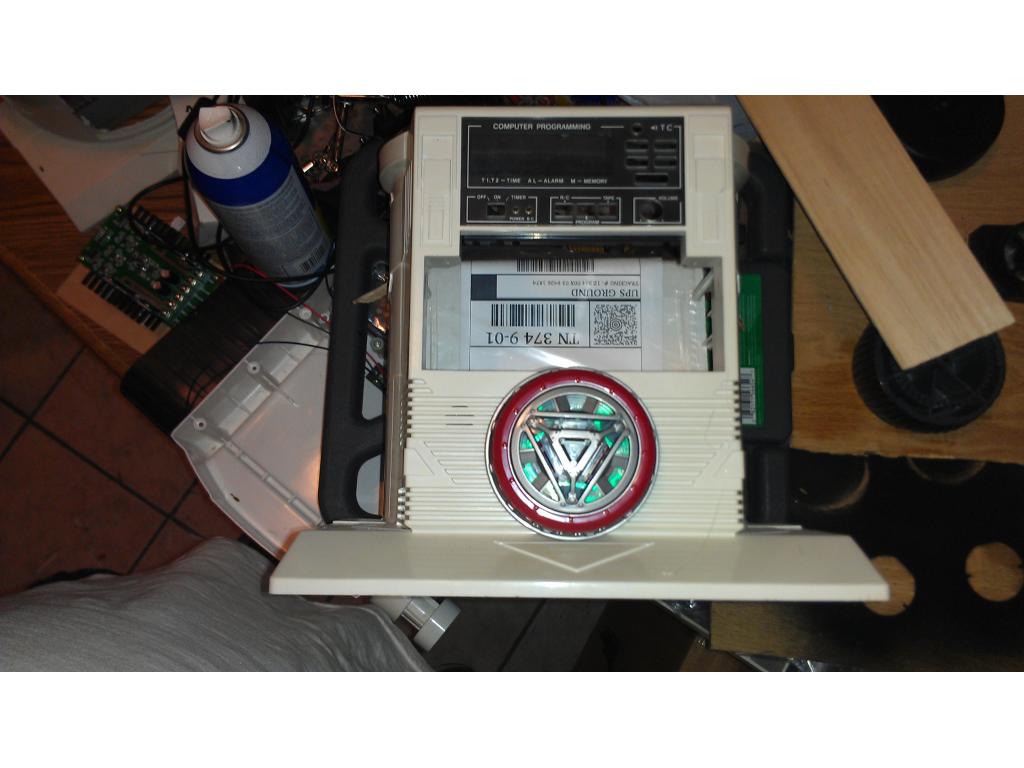
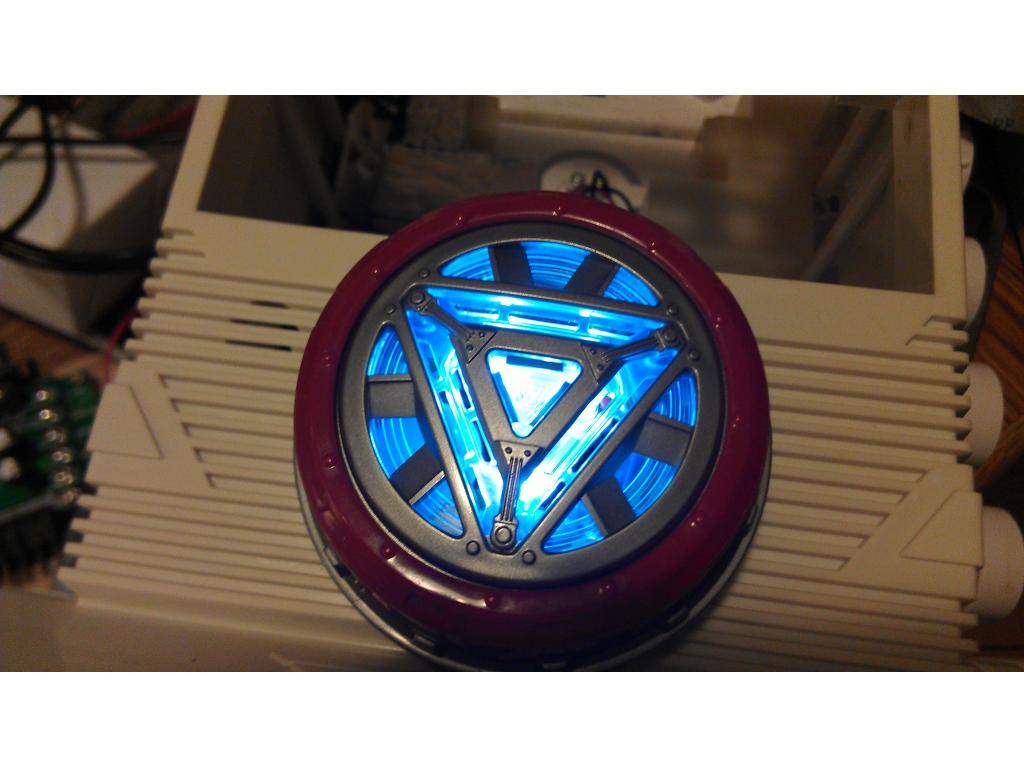
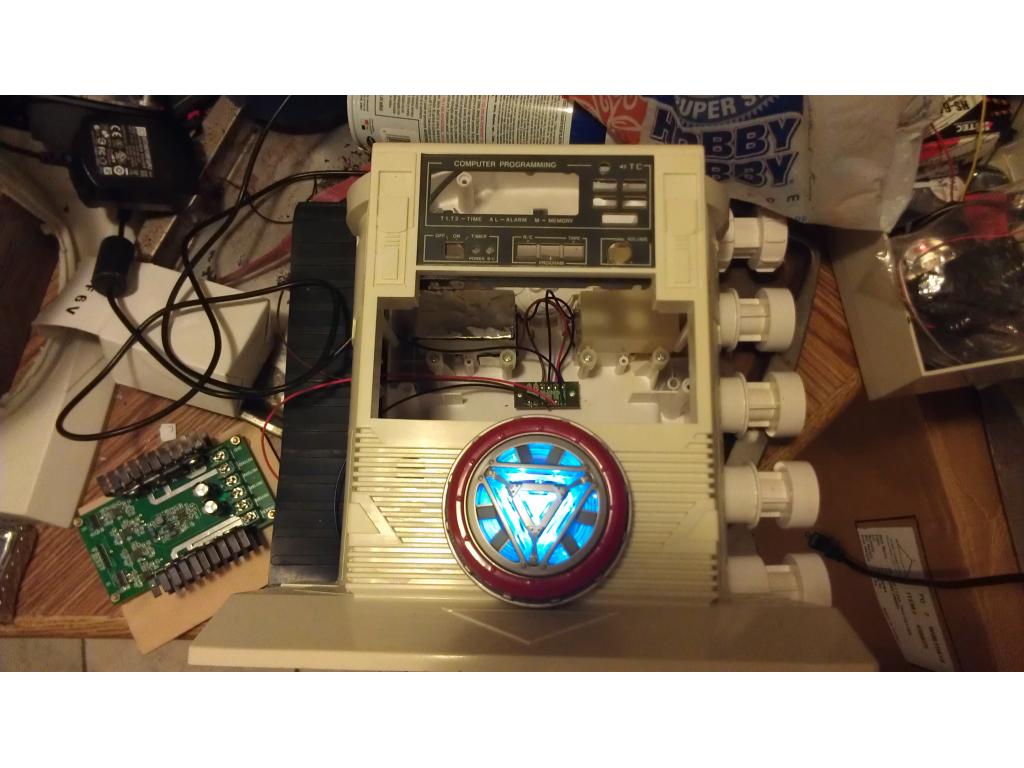
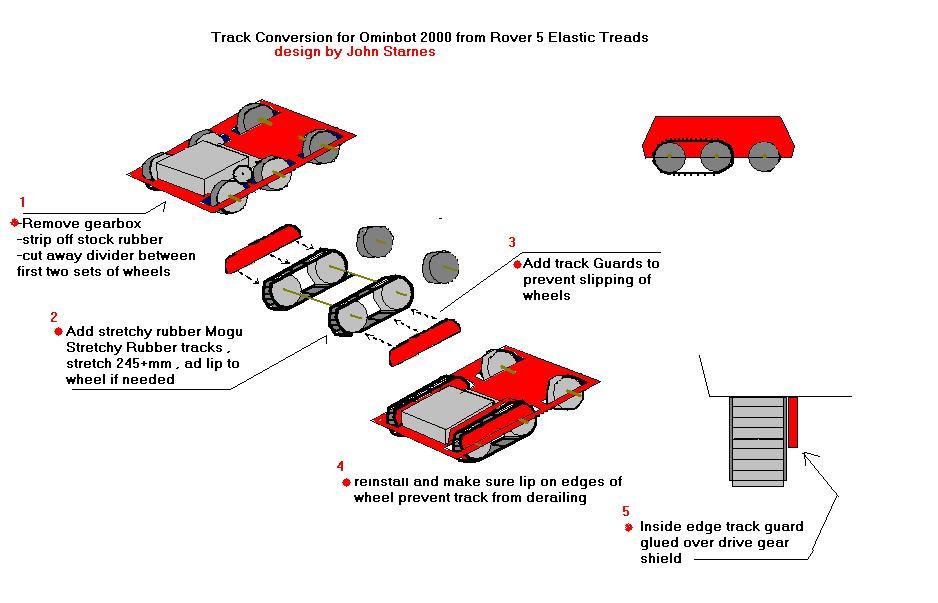
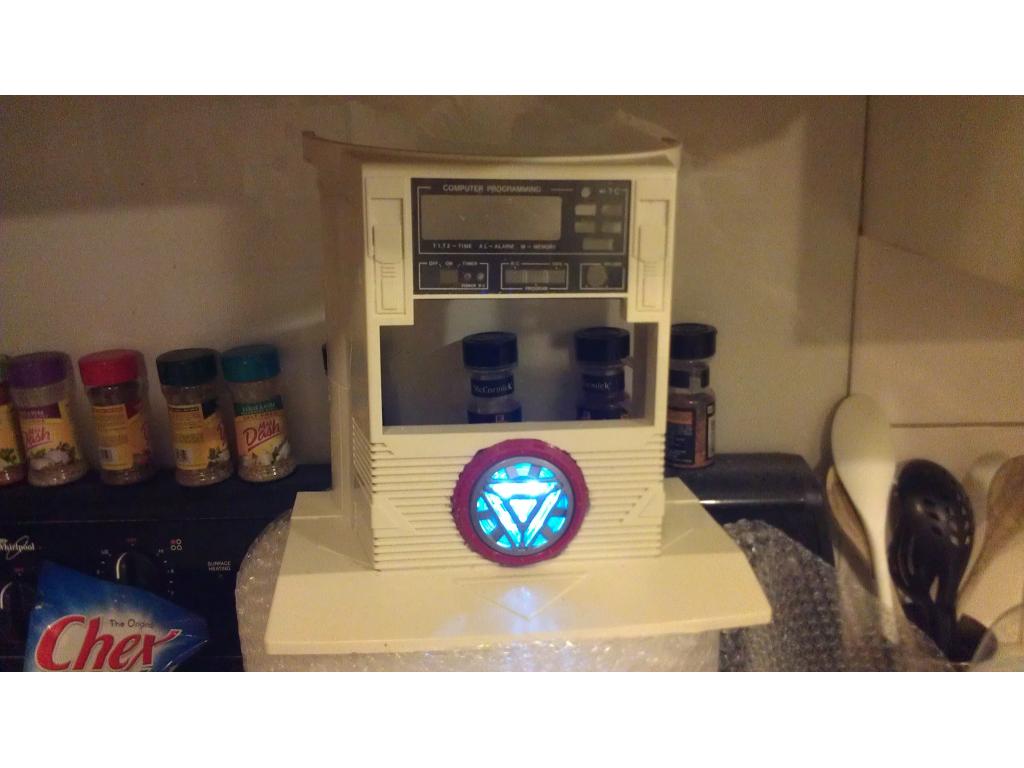
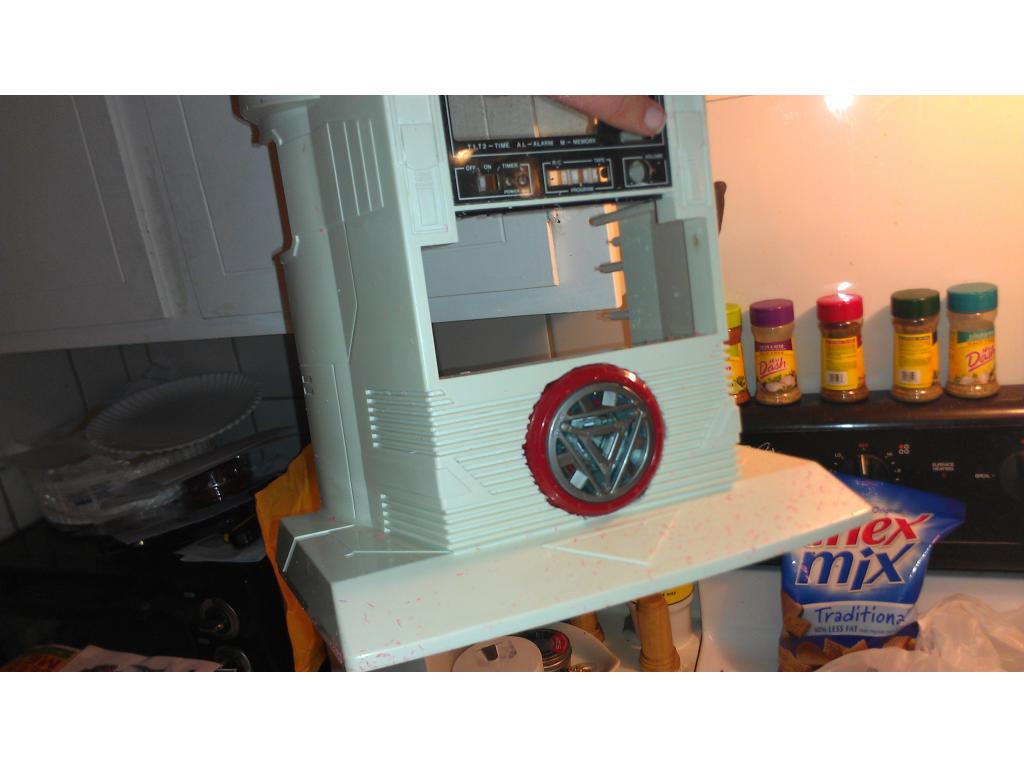
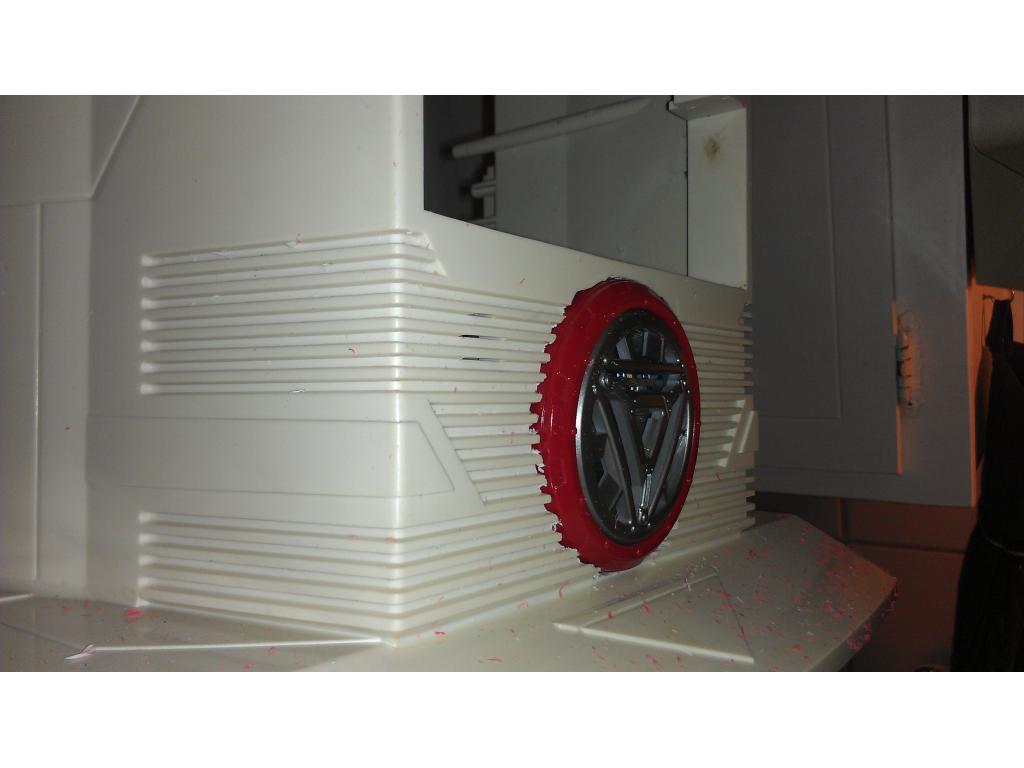
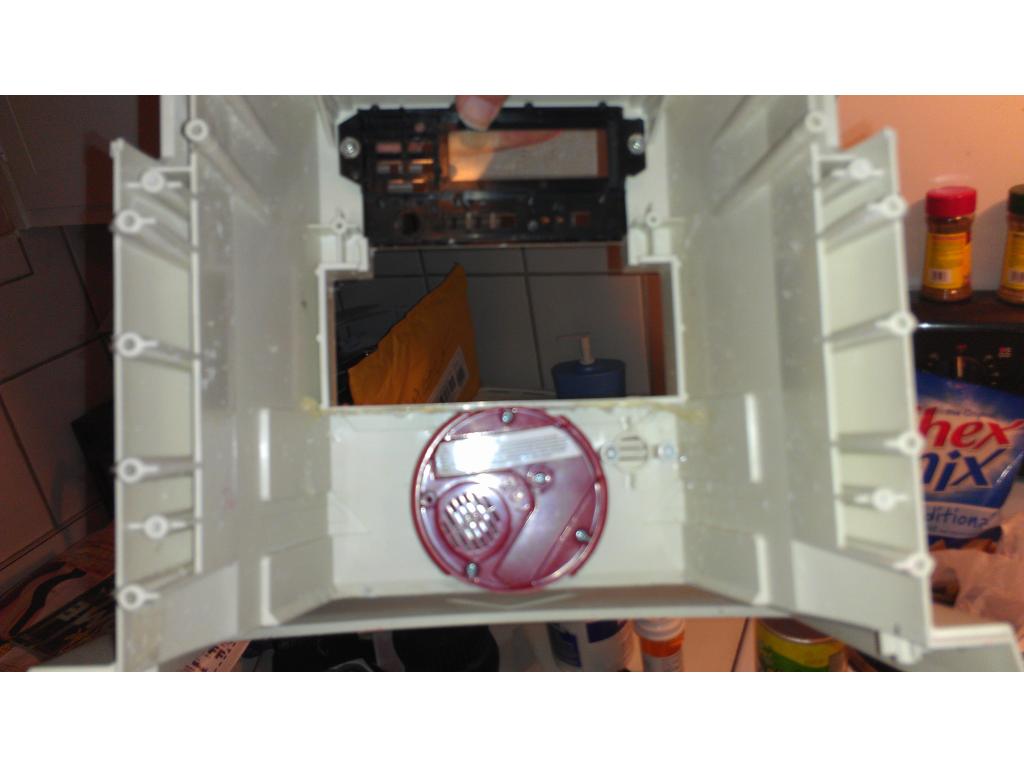
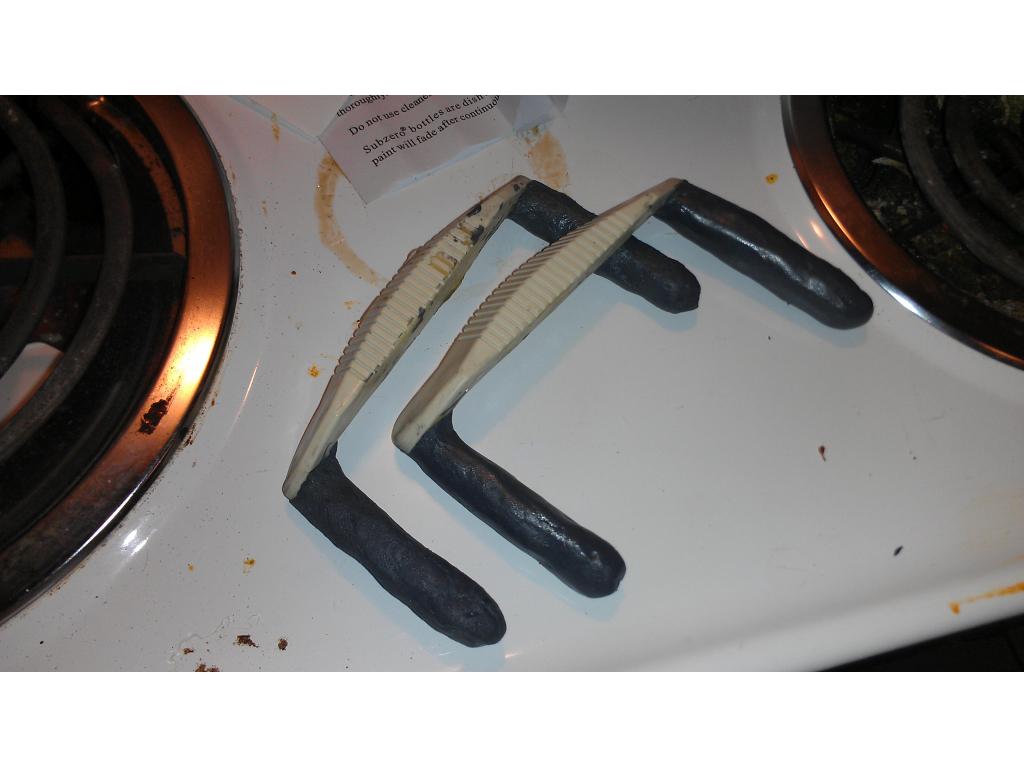
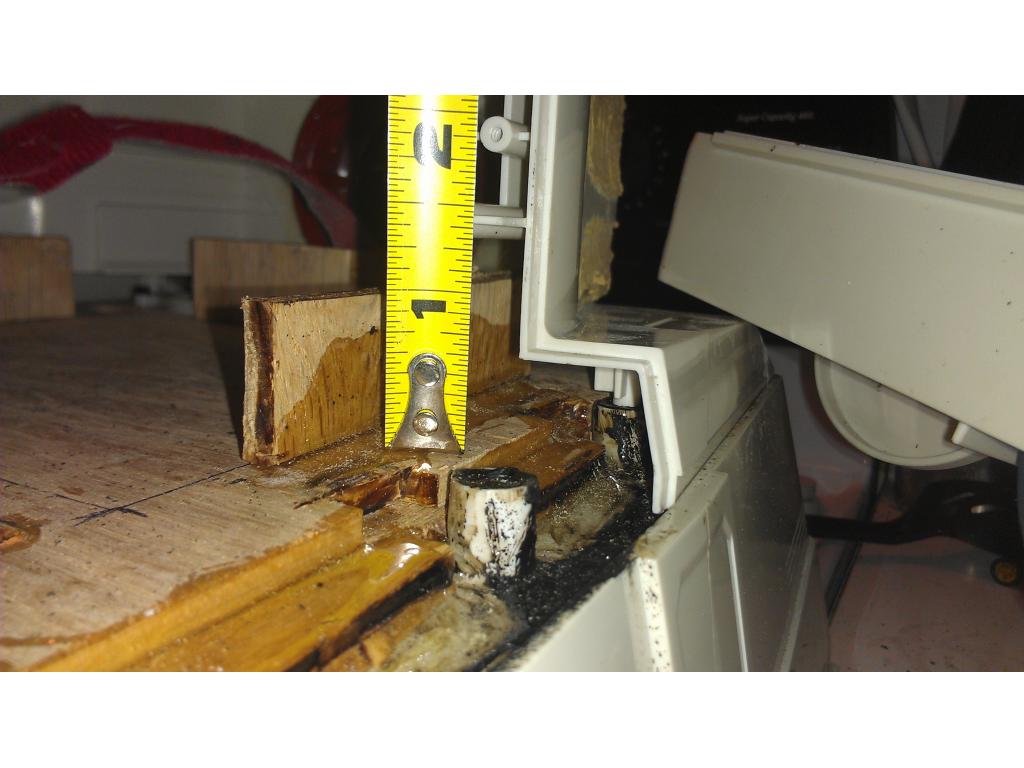
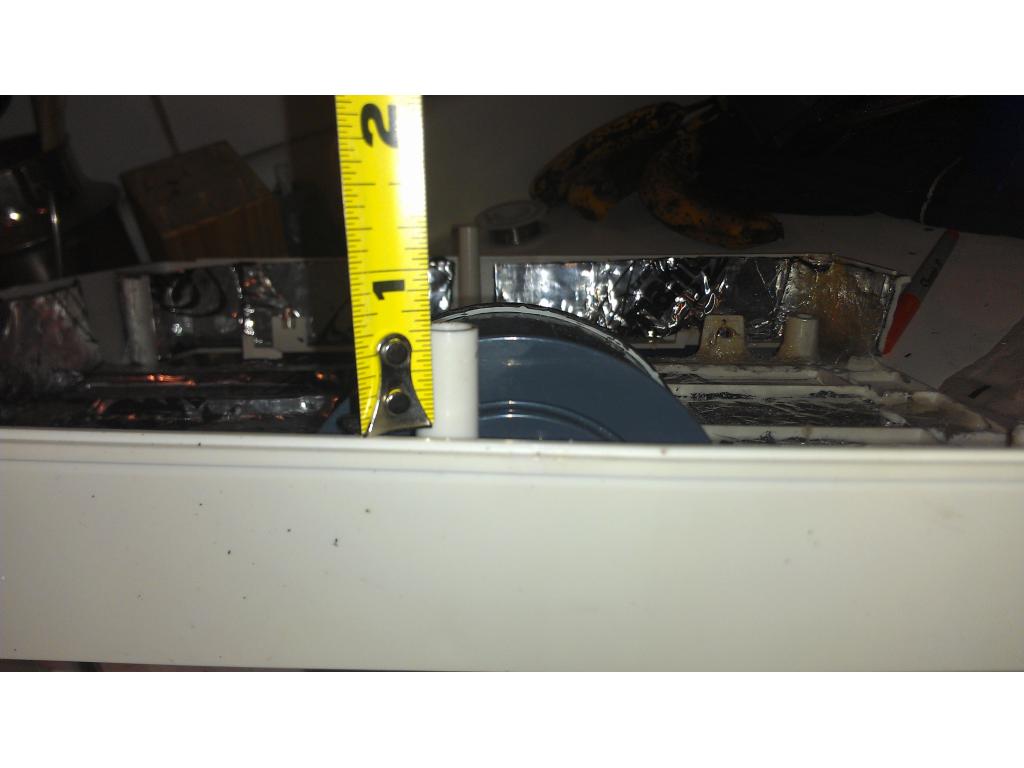
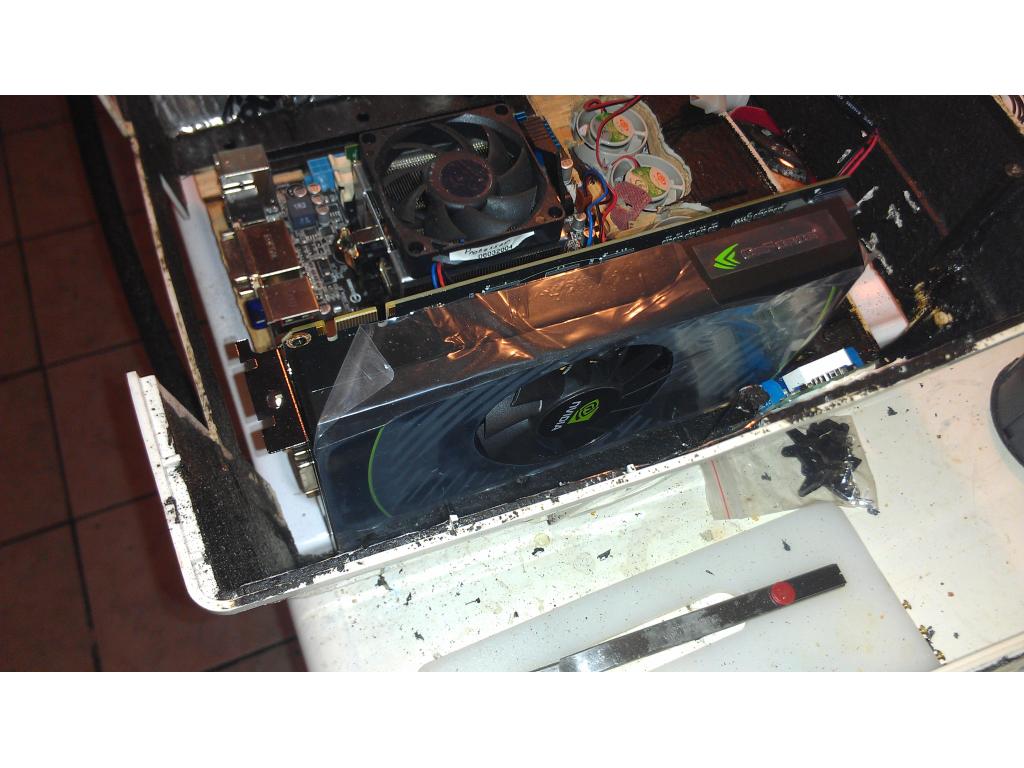
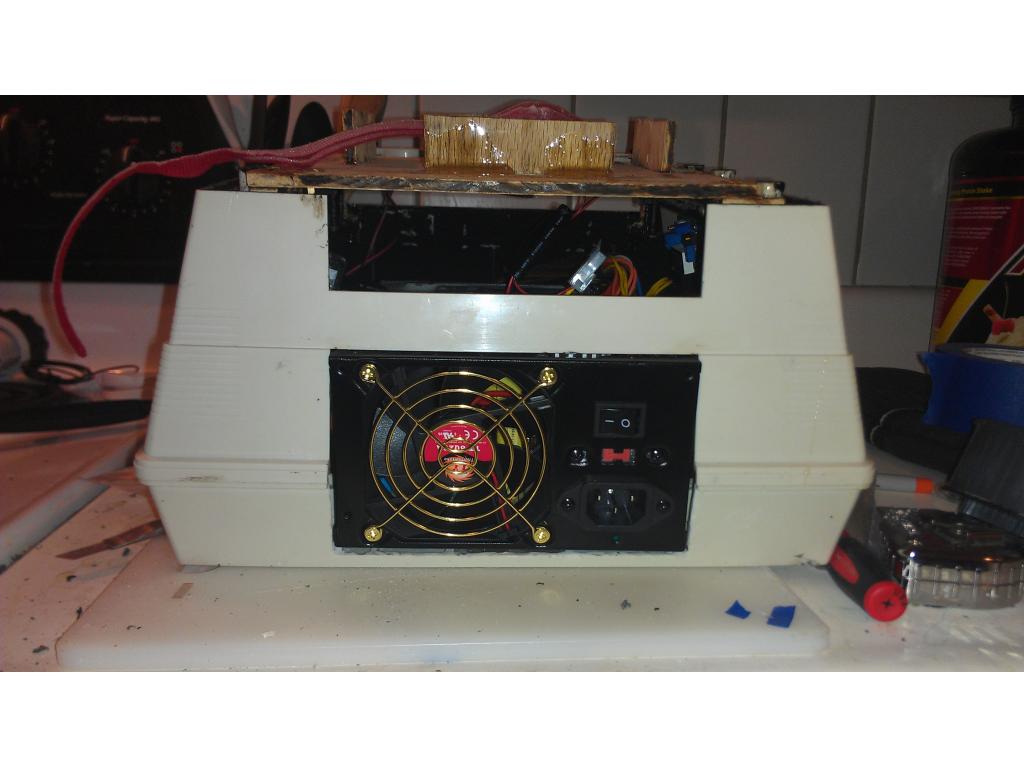
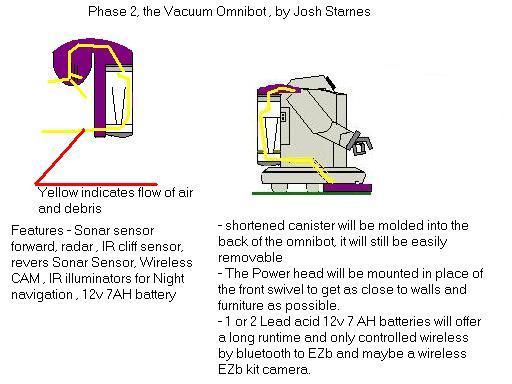
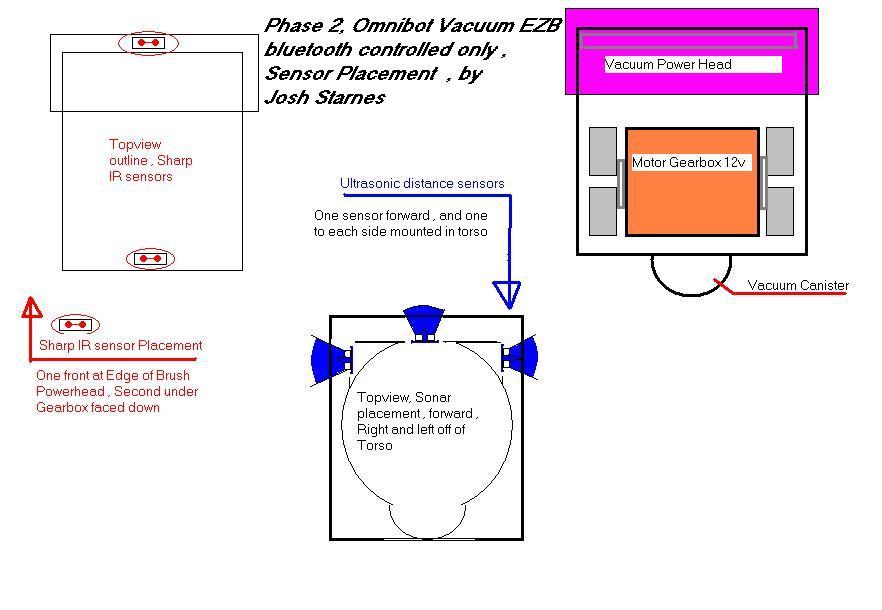
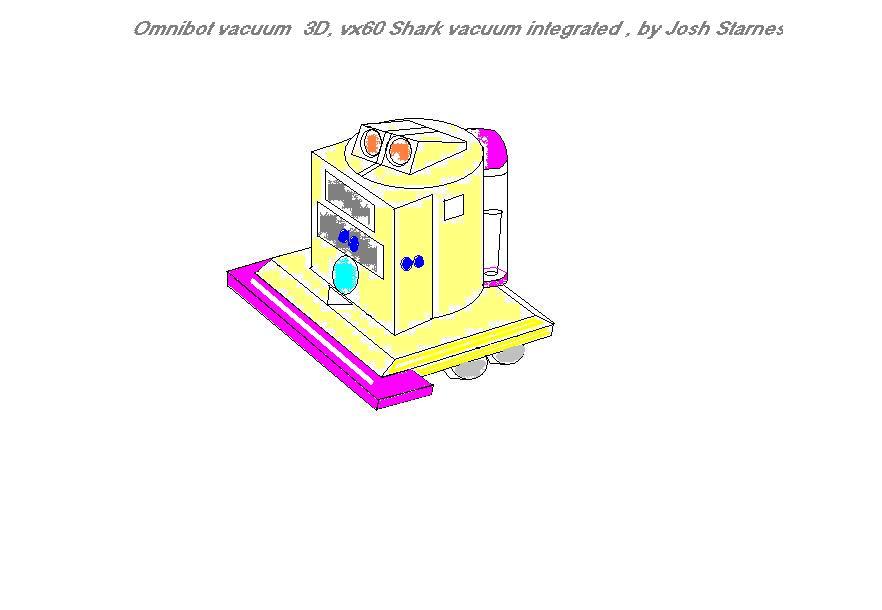
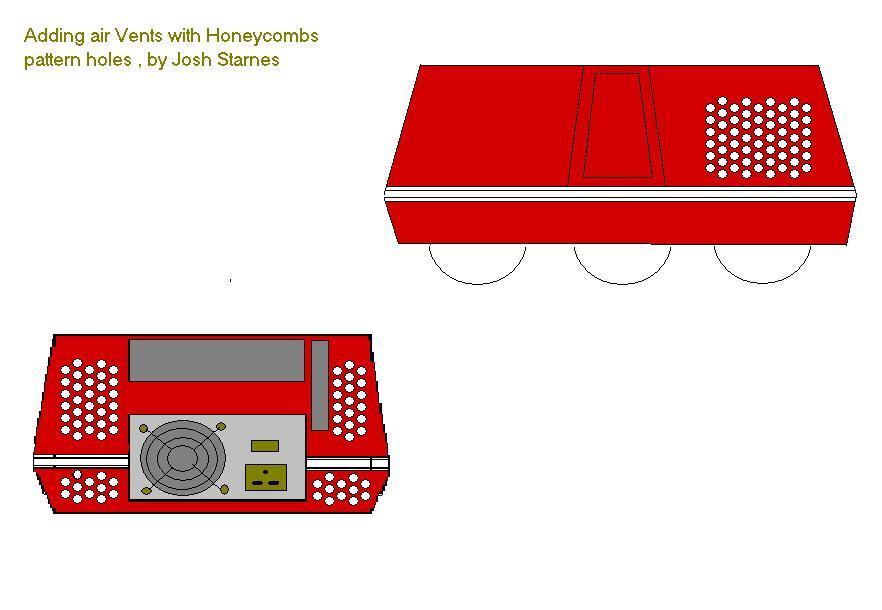
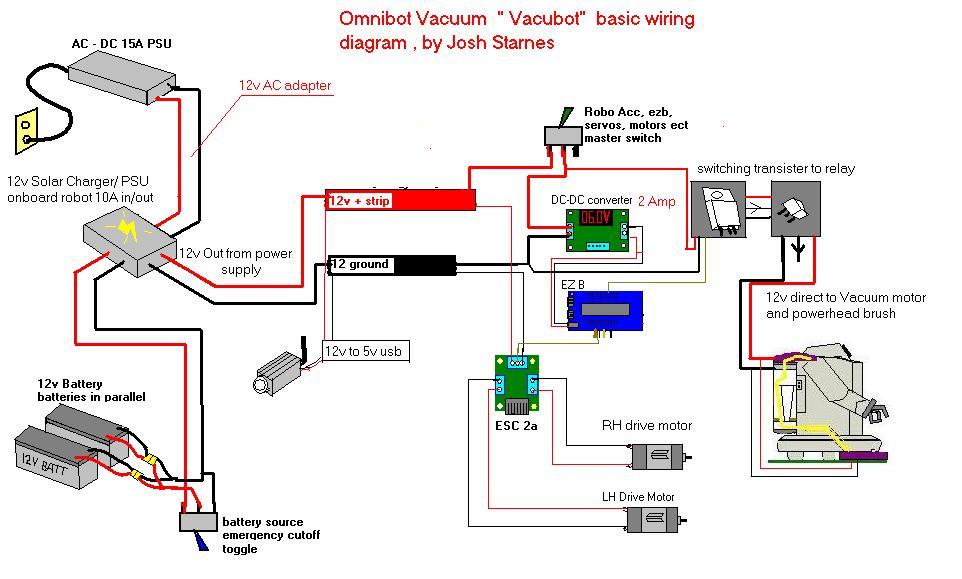
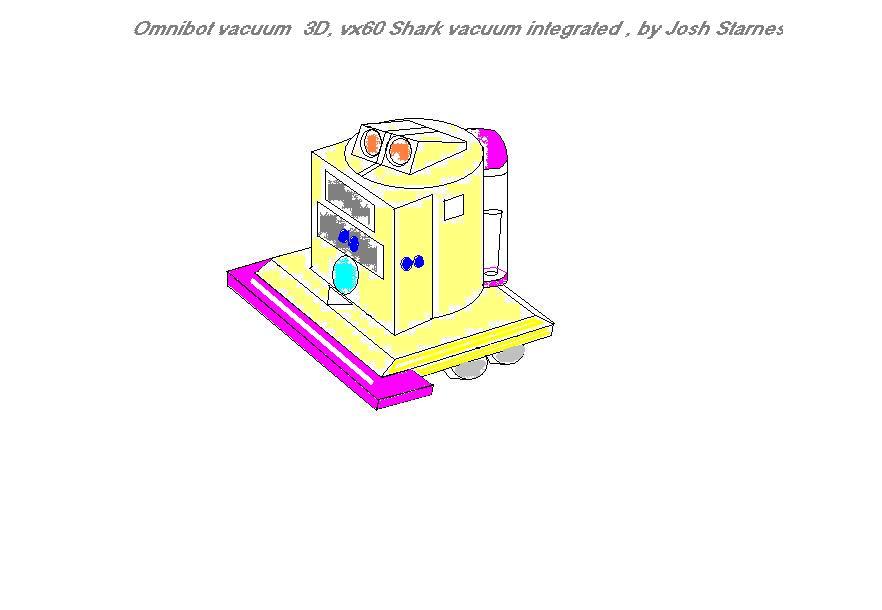
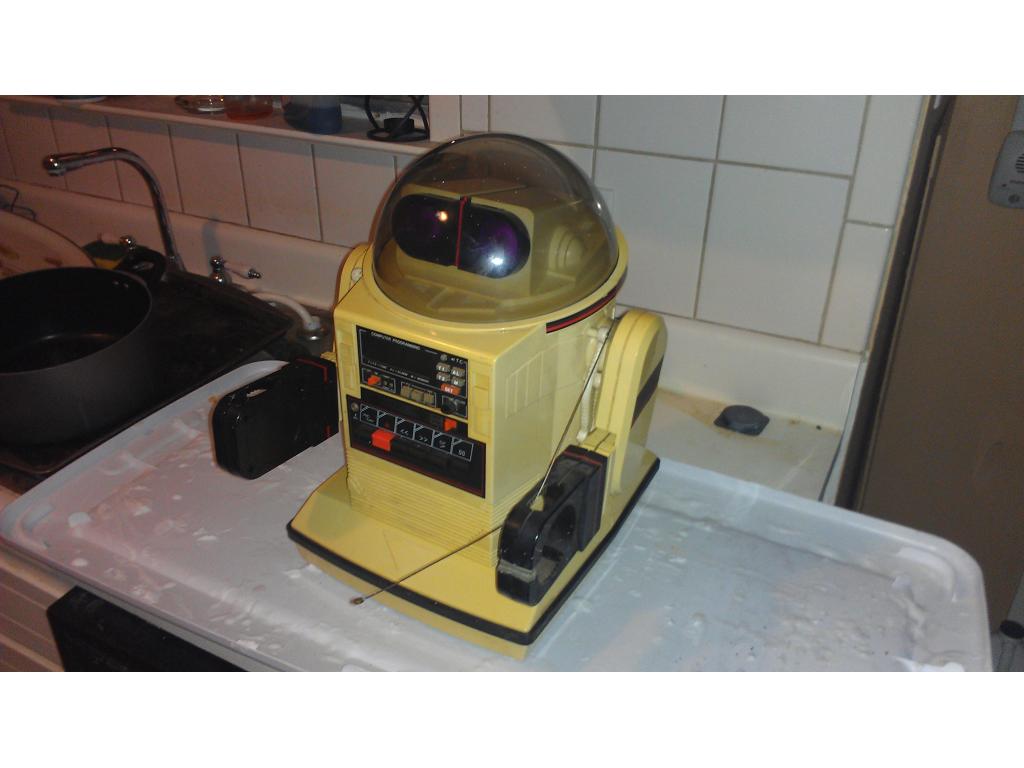
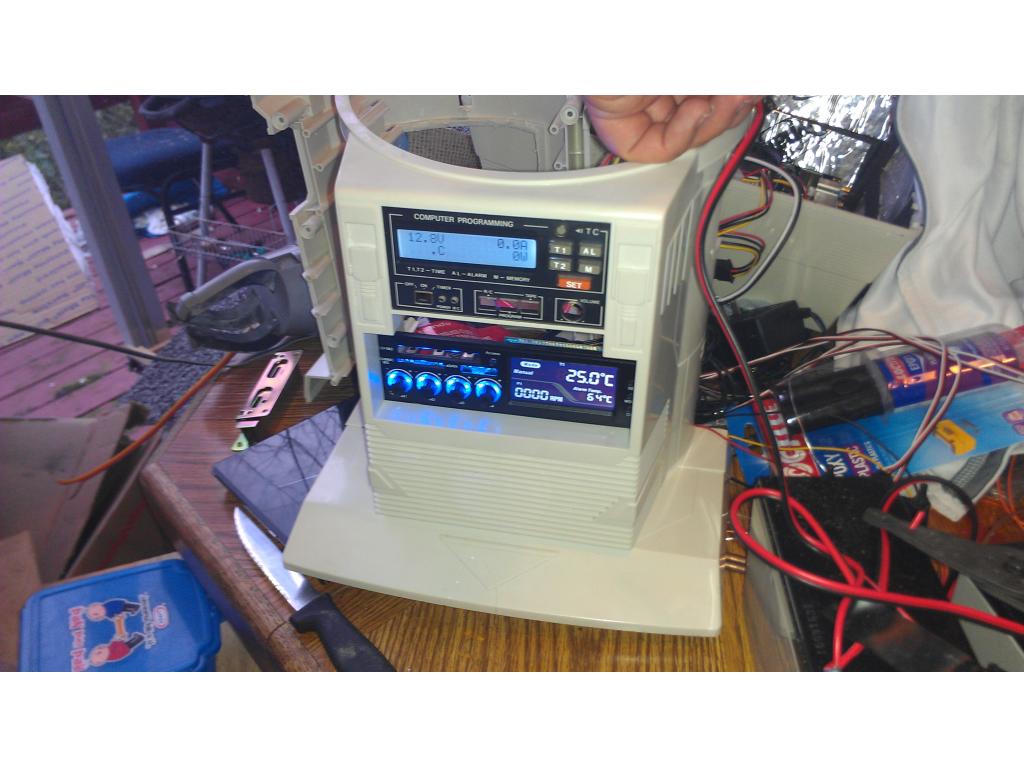
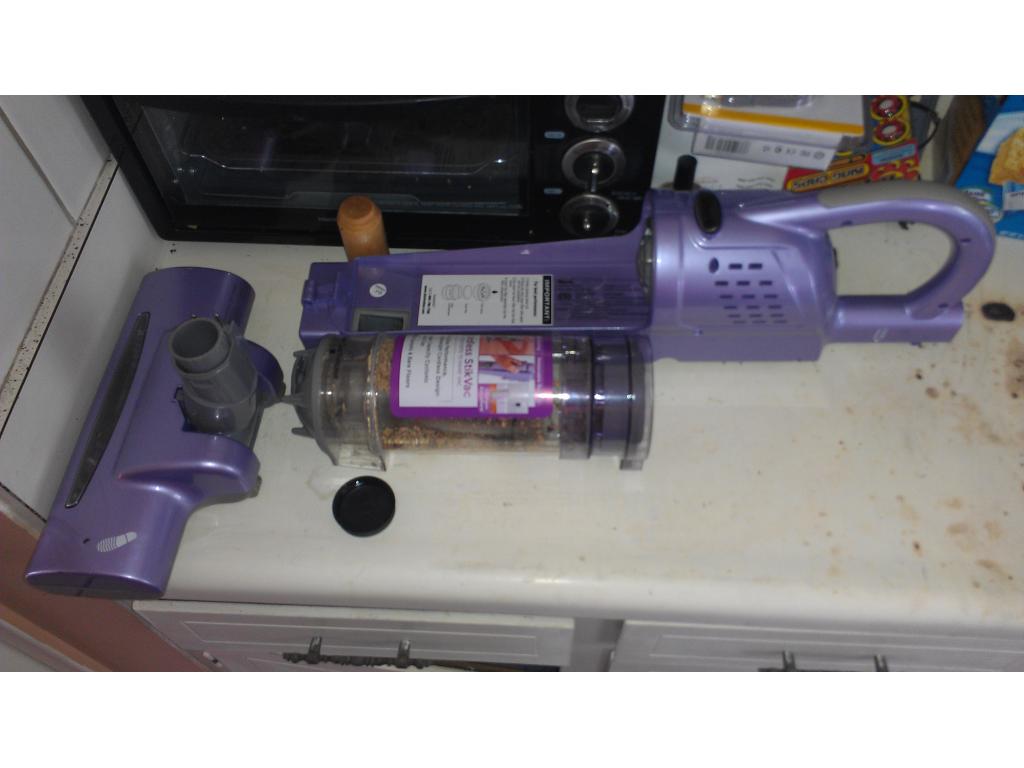
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.

By jstarne1
— Last update

Discover more robots
Ericez's Mini Chappie Project
Create a mini Chappie head from 3D-printed parts, first movement demo using Ez-Board.
Andy's Lilian Is Assembled And Running
Lilian DIY robot with EZB v4: face/color tracking, voice-controlled drive, arm servos and grippers, MP3 replies; owner...
DJ's DJ's Omnibot 2000
Omnibot 2000 showcases Synthiam ARC: Wii Remote control, Glyph vision recognition, Tablet PC touch control and materials...

Haha
Plastic epoxy obtained! Left the house to get hemhawks, I guess the first video will be soon.

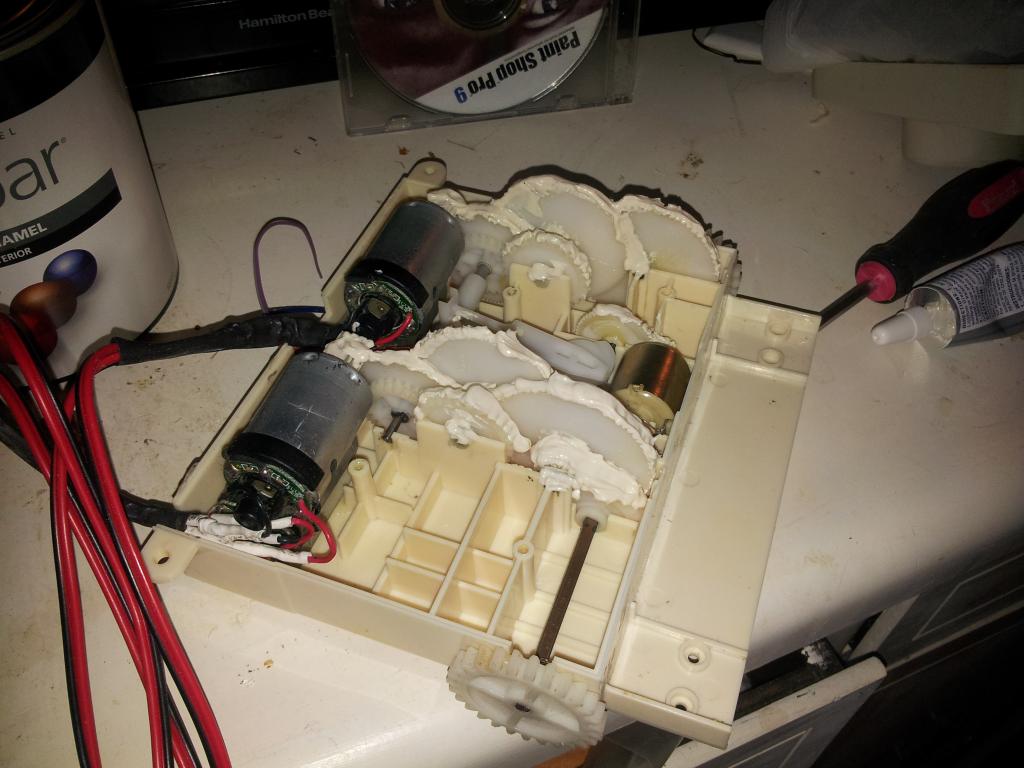
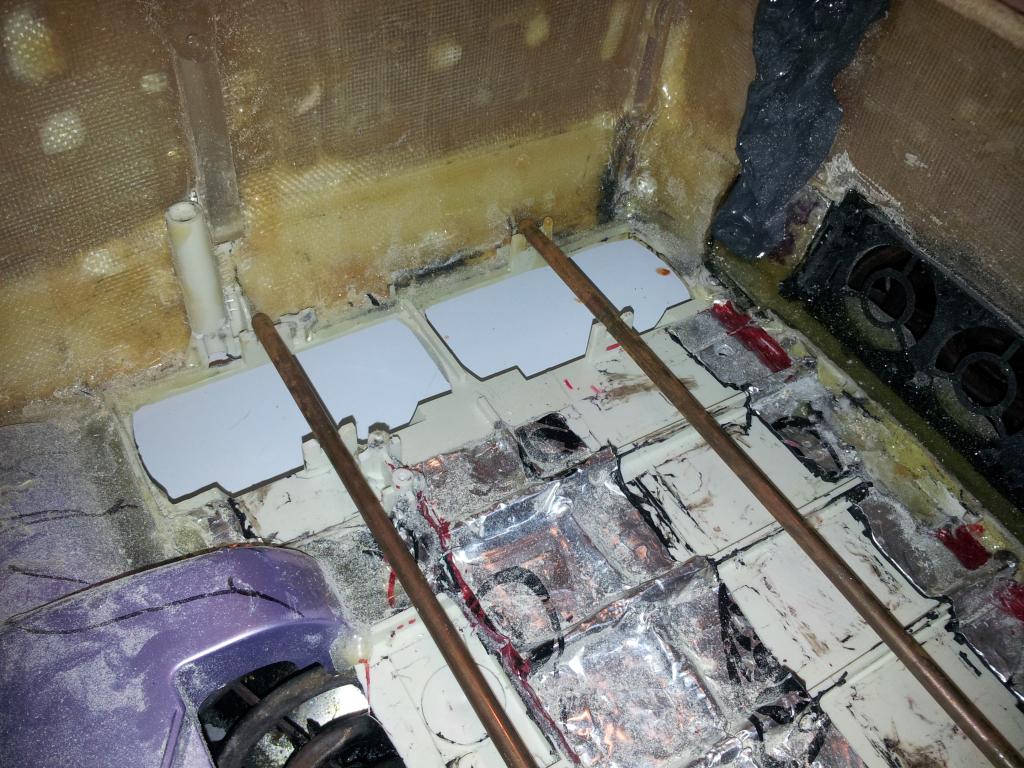
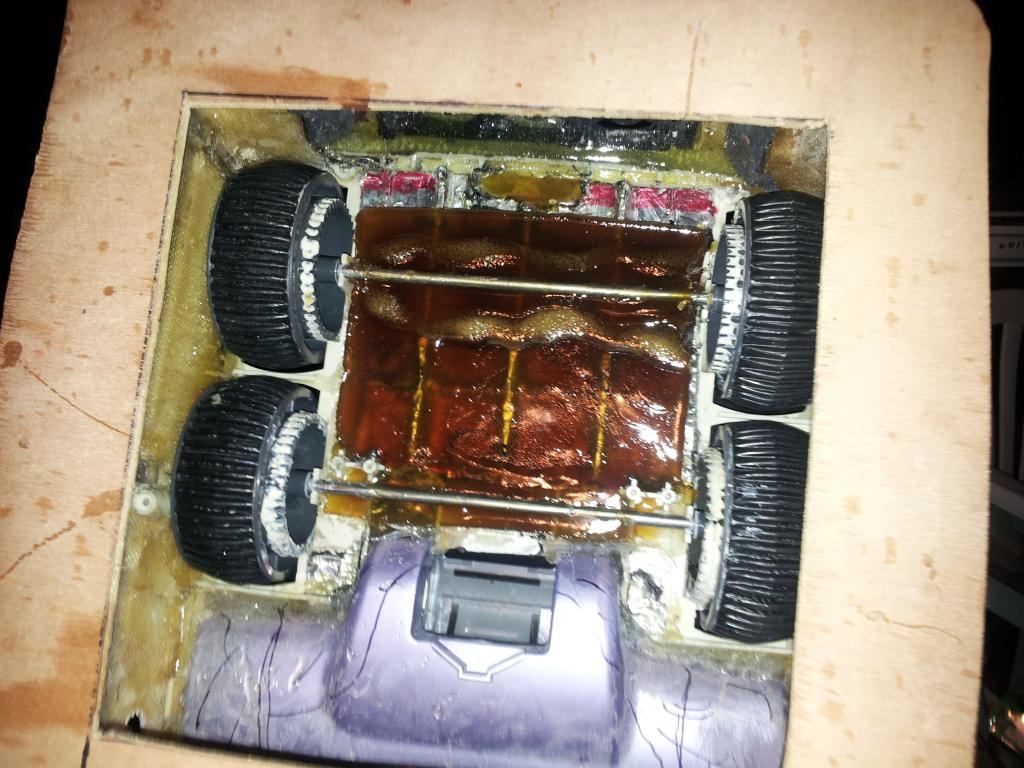
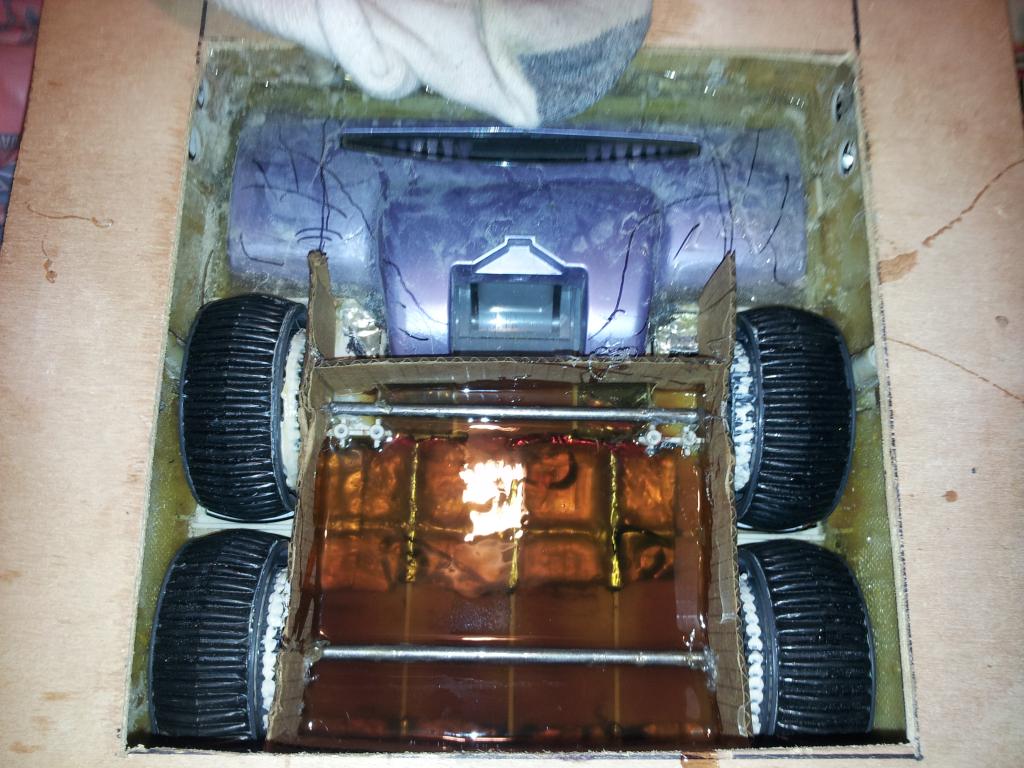
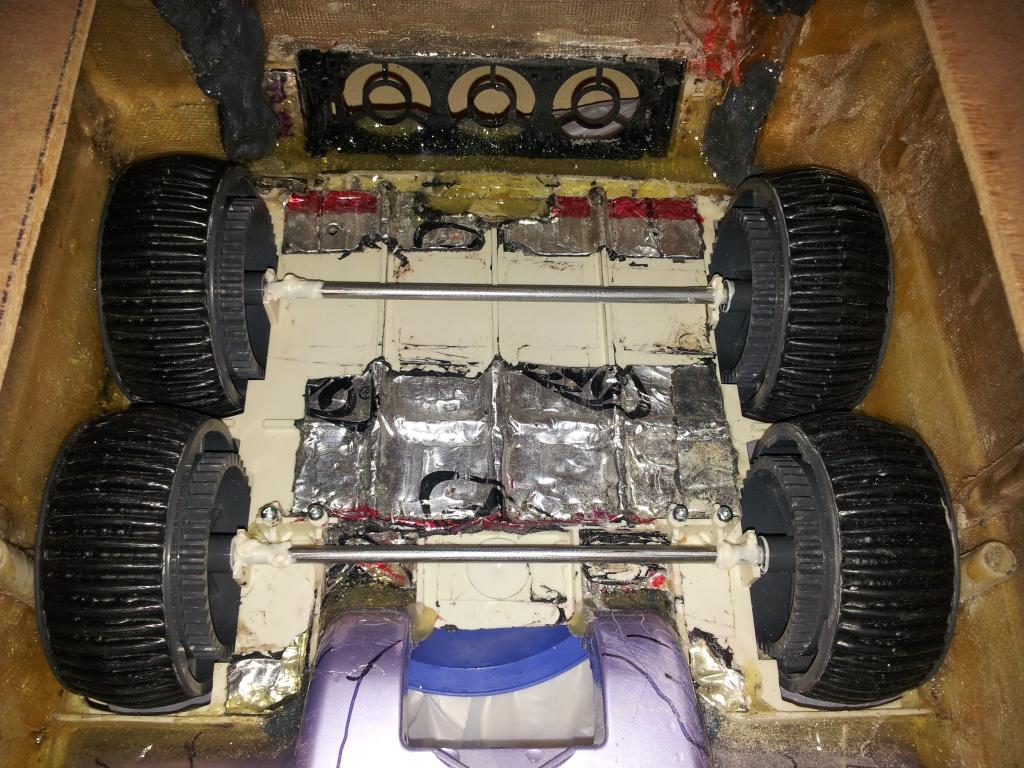
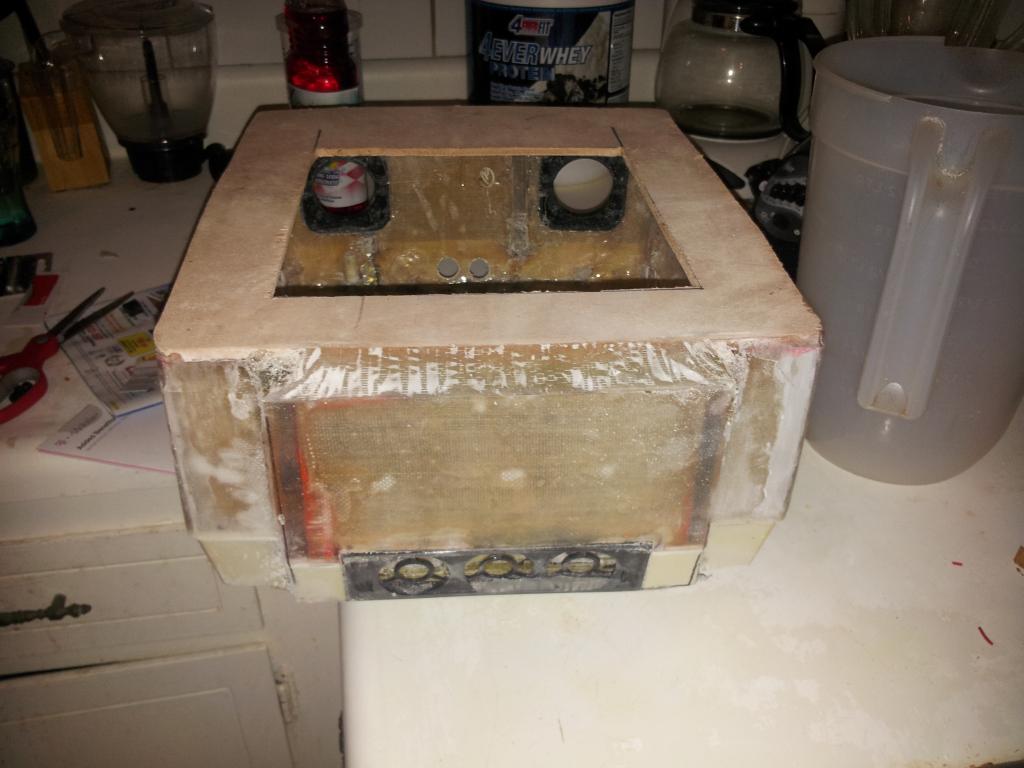
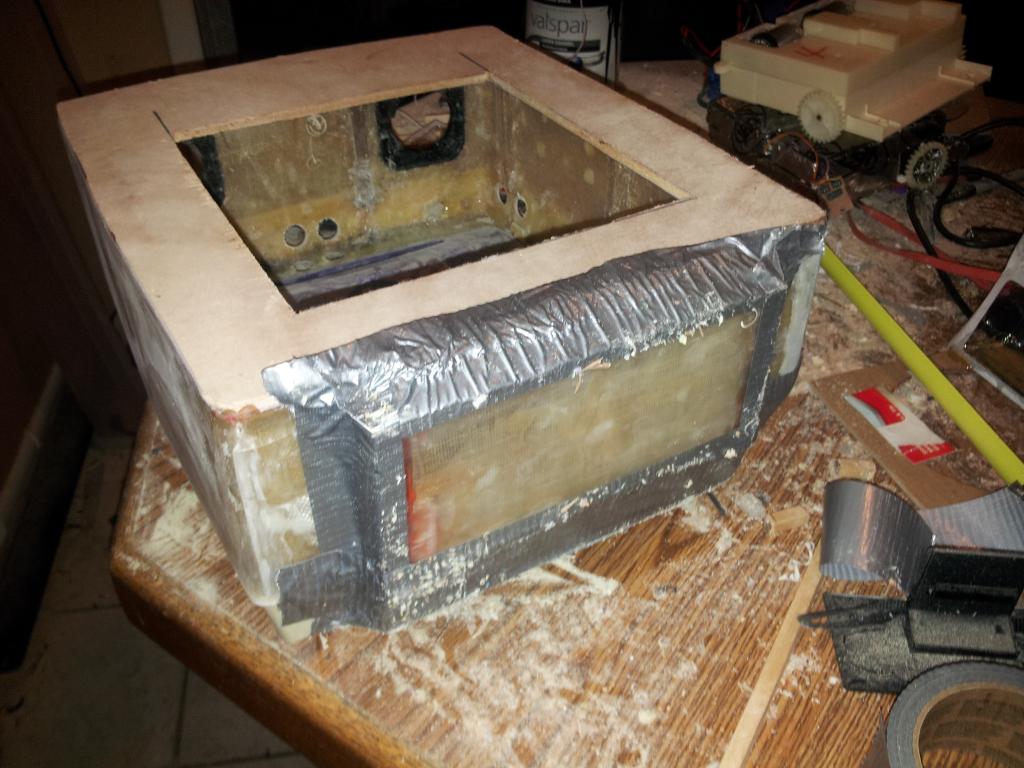
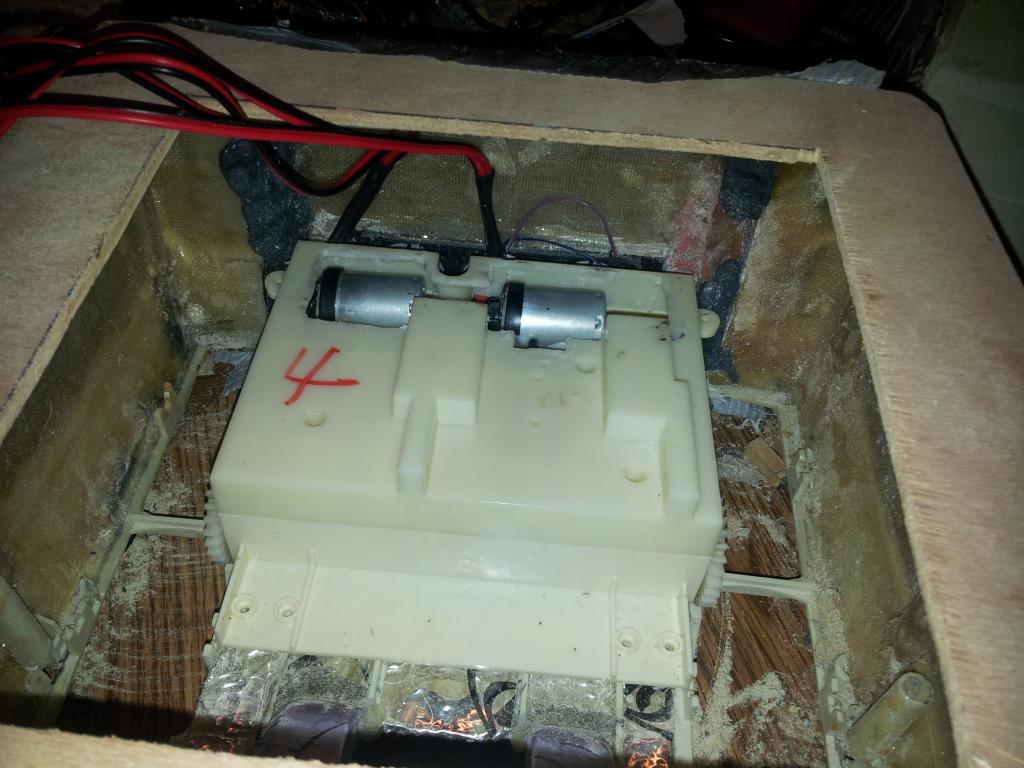
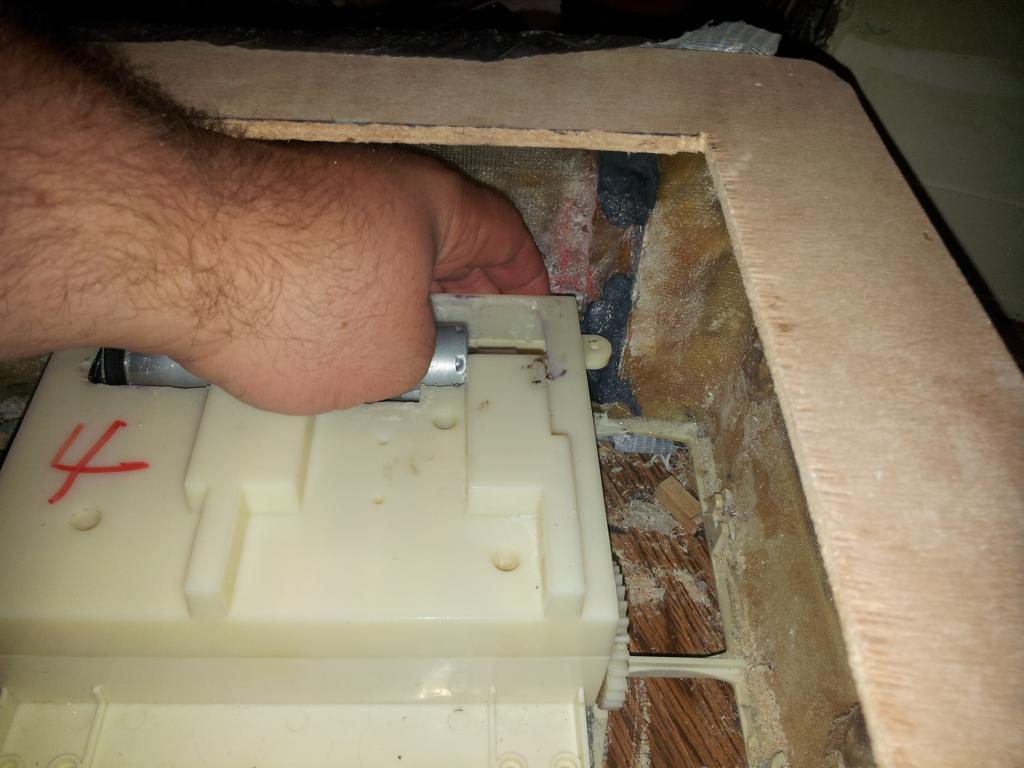
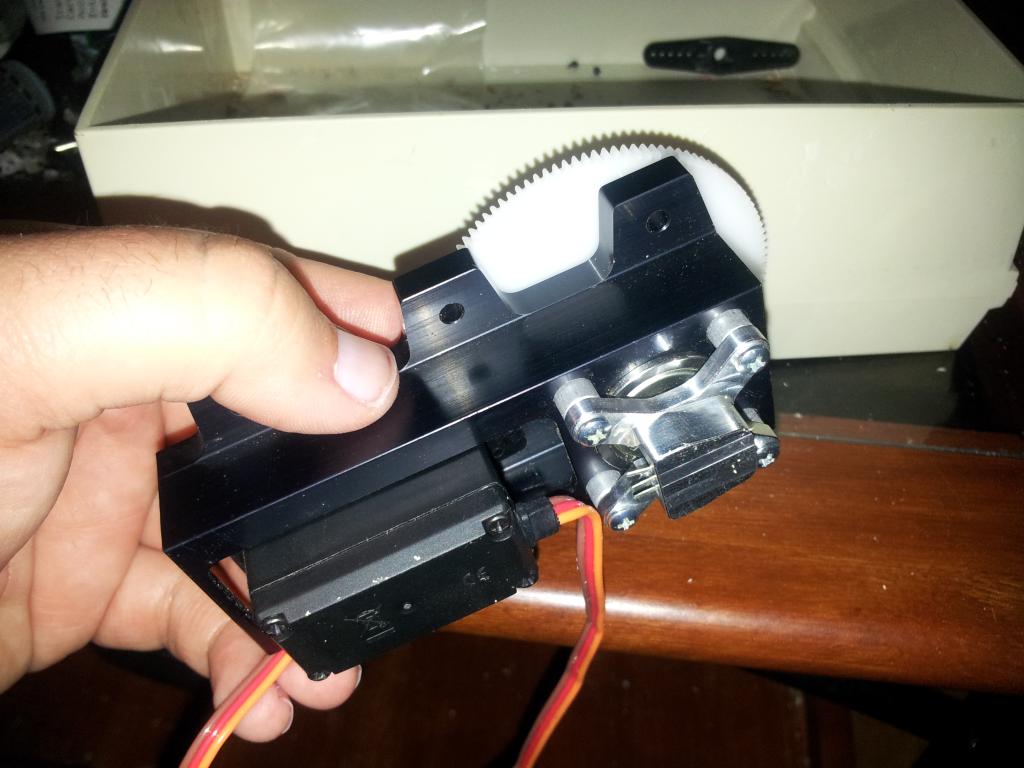
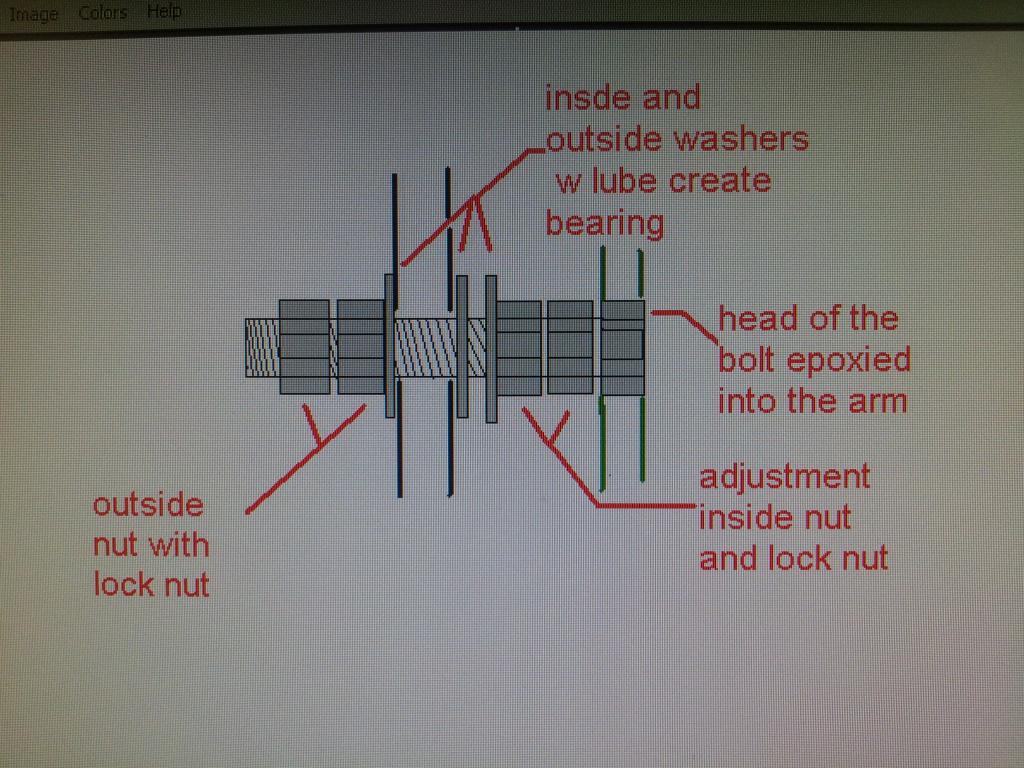
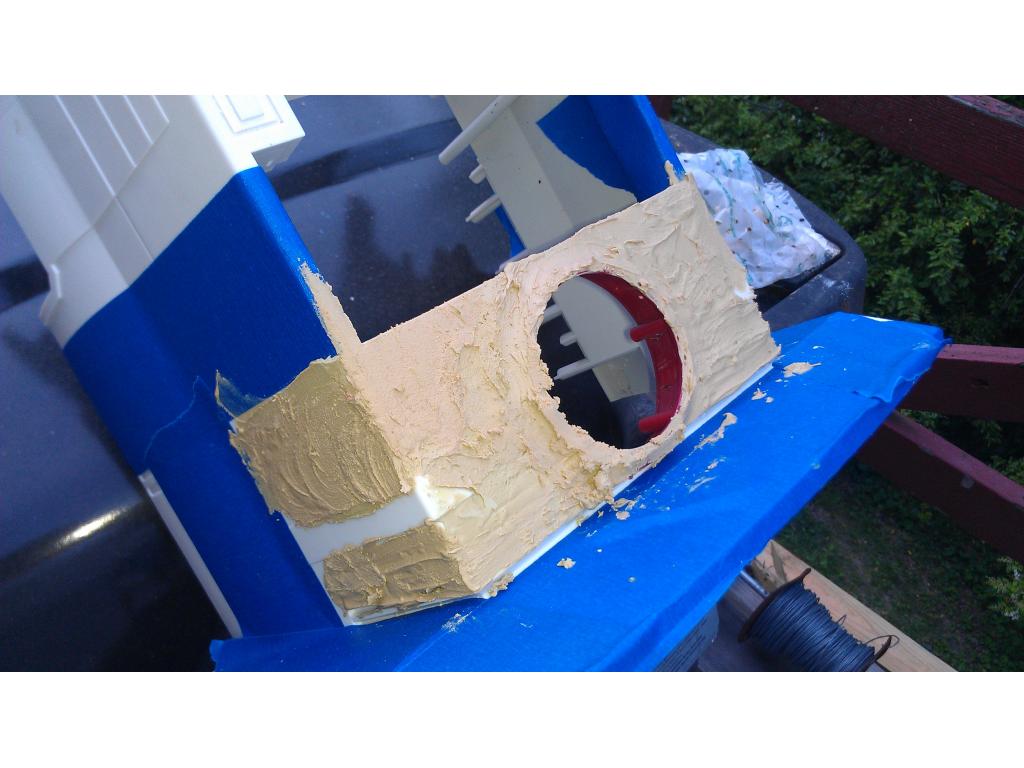
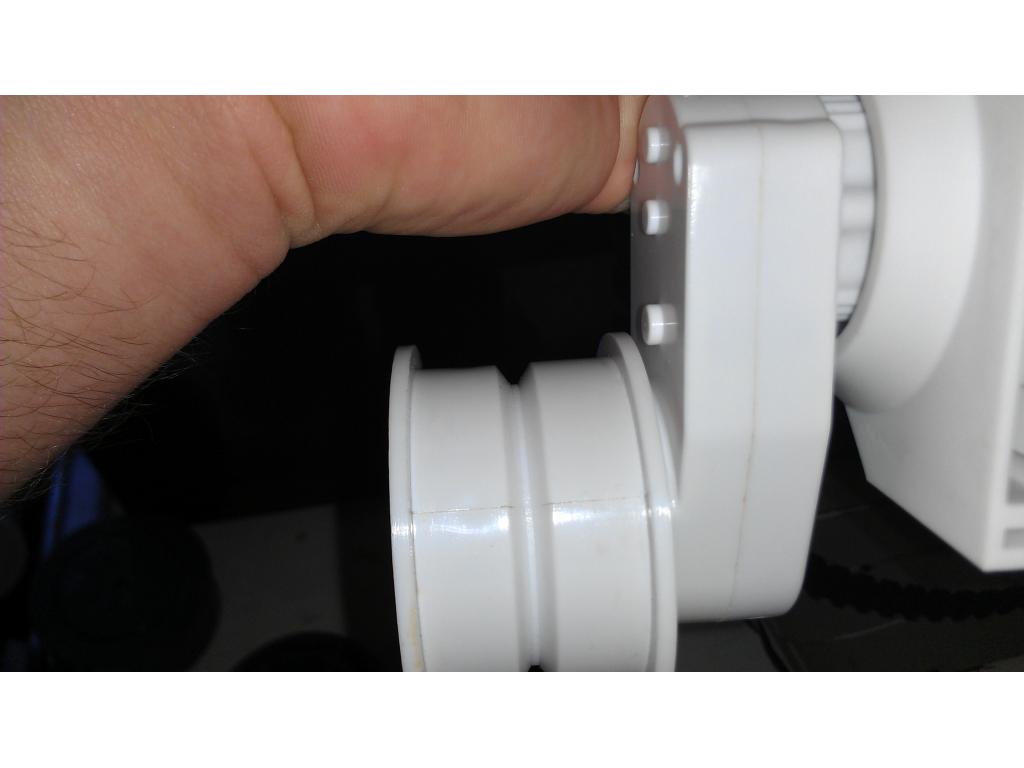
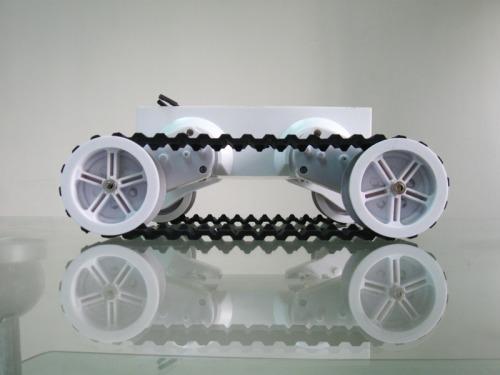
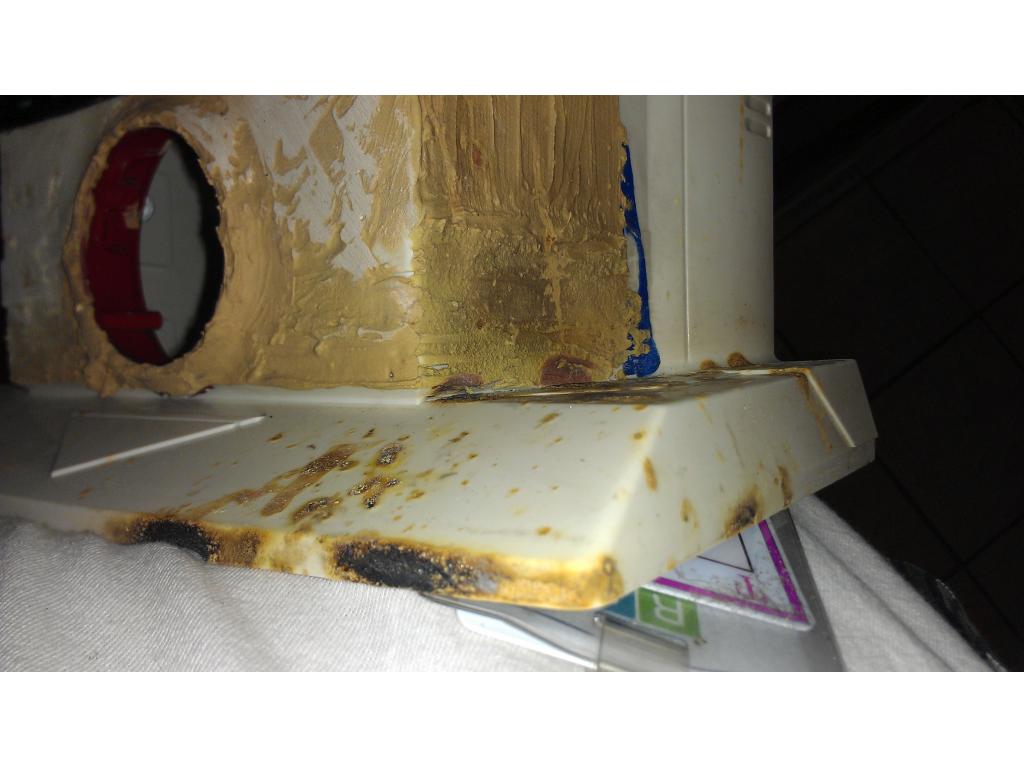
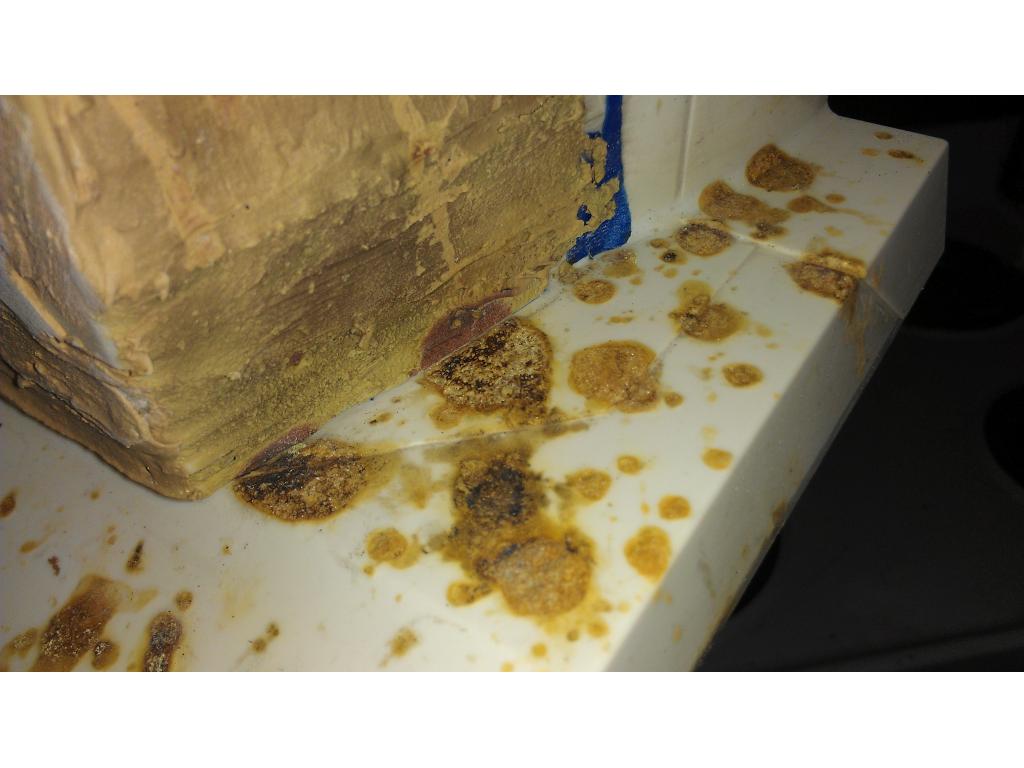
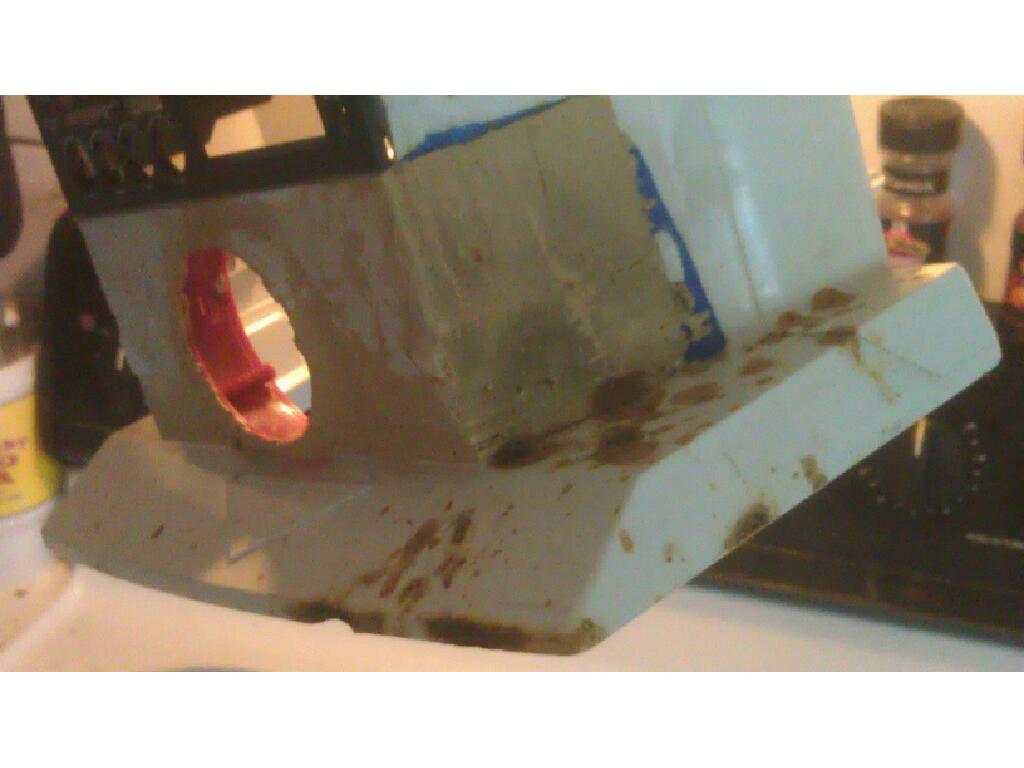
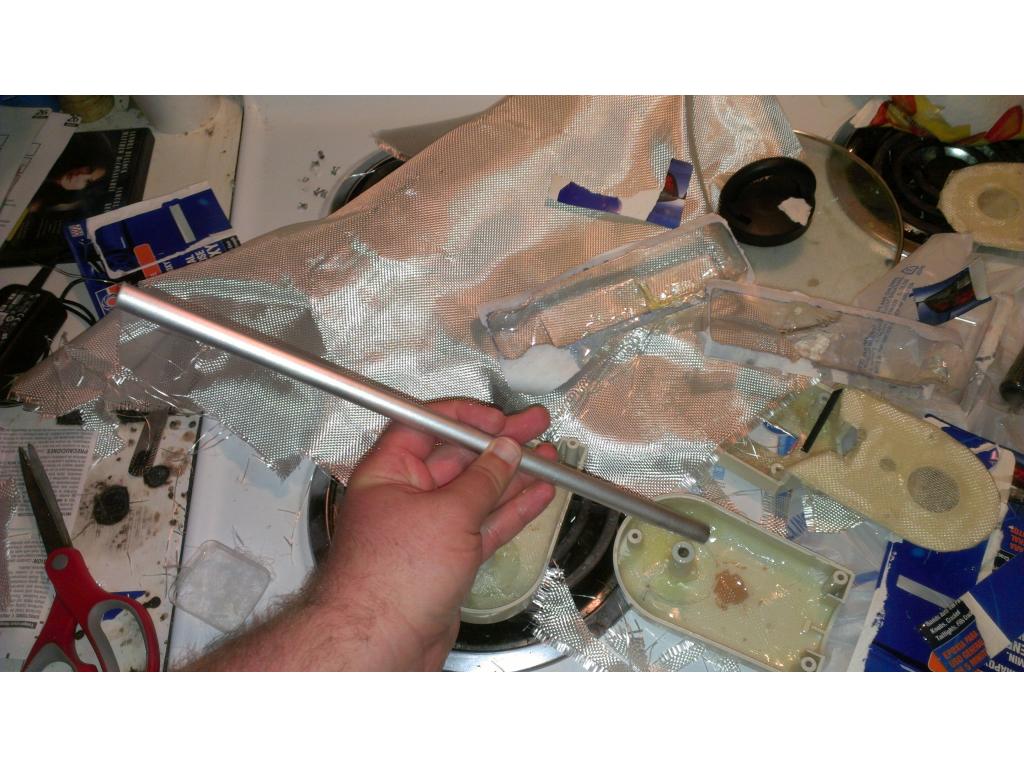
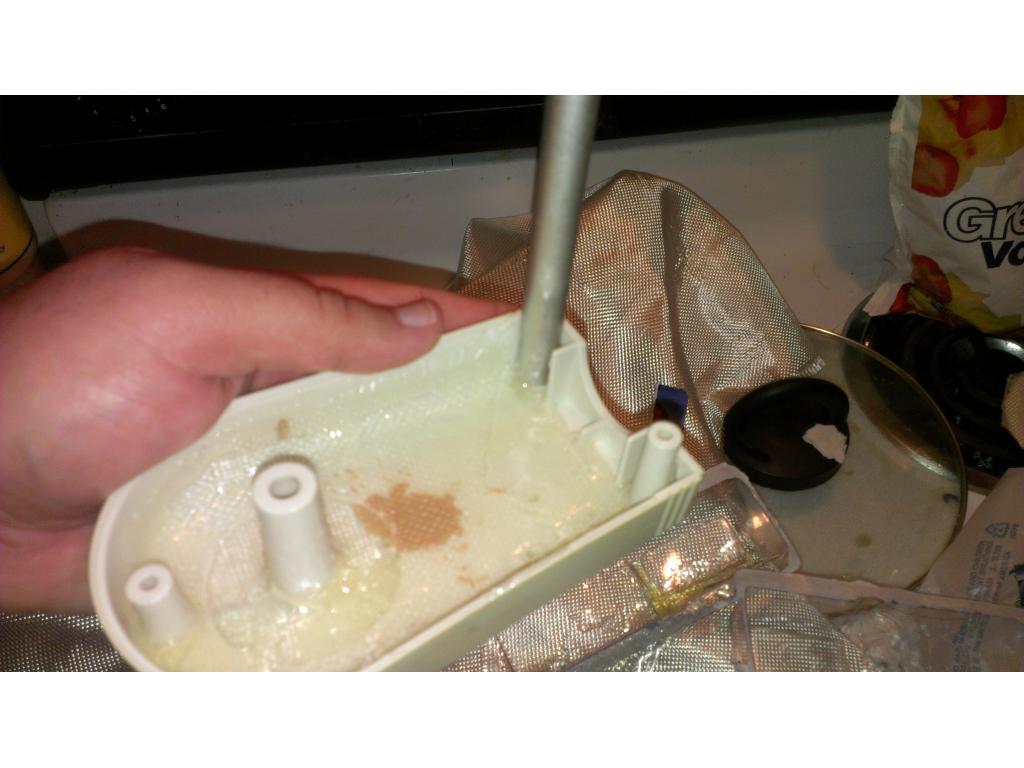
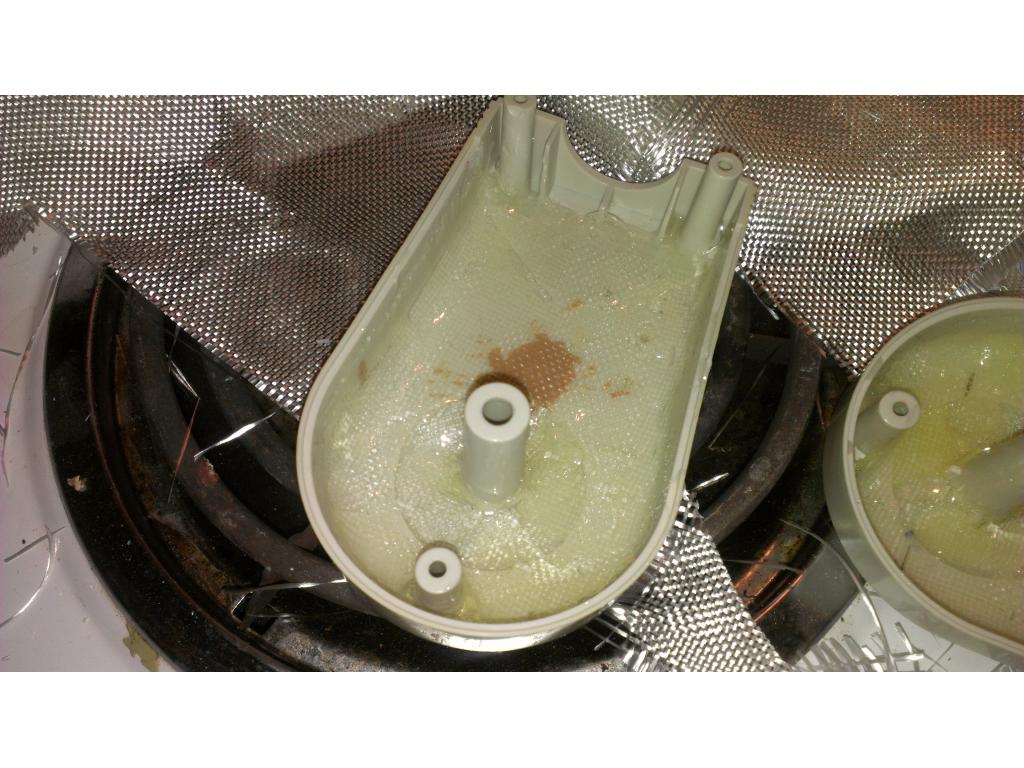
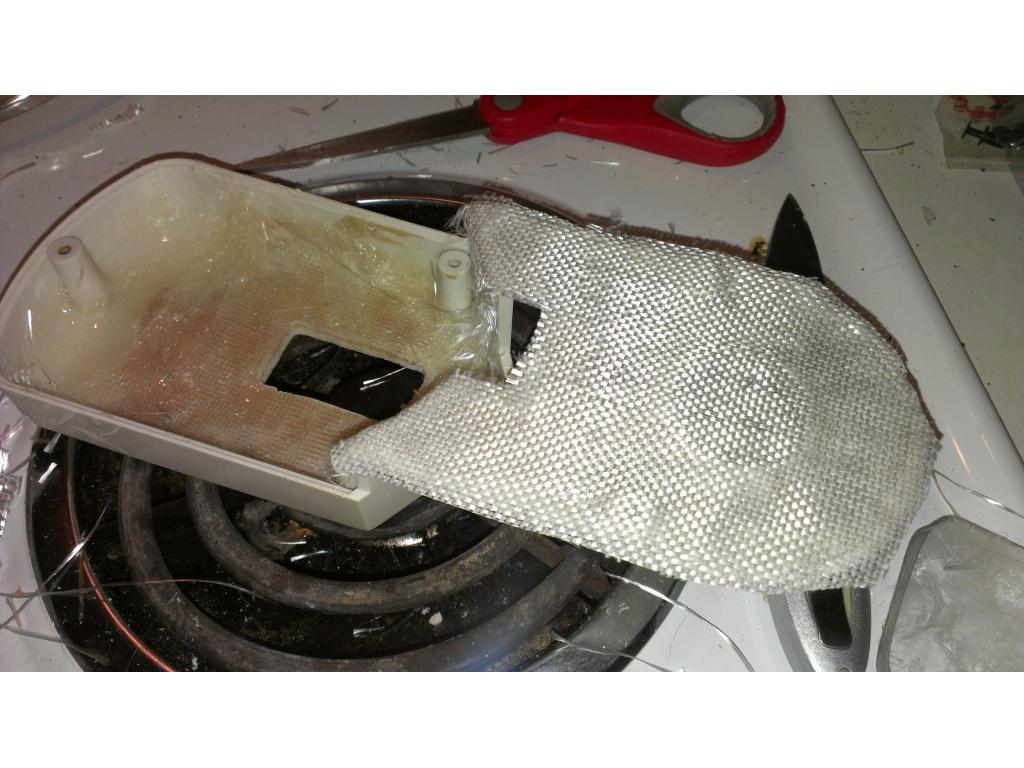
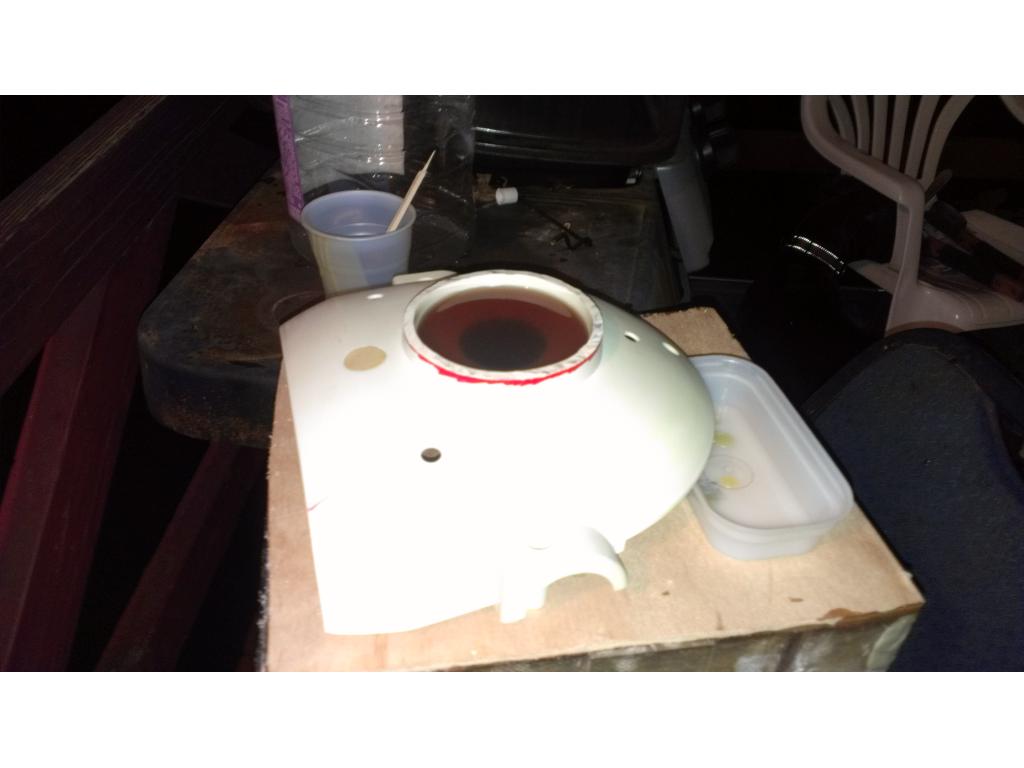
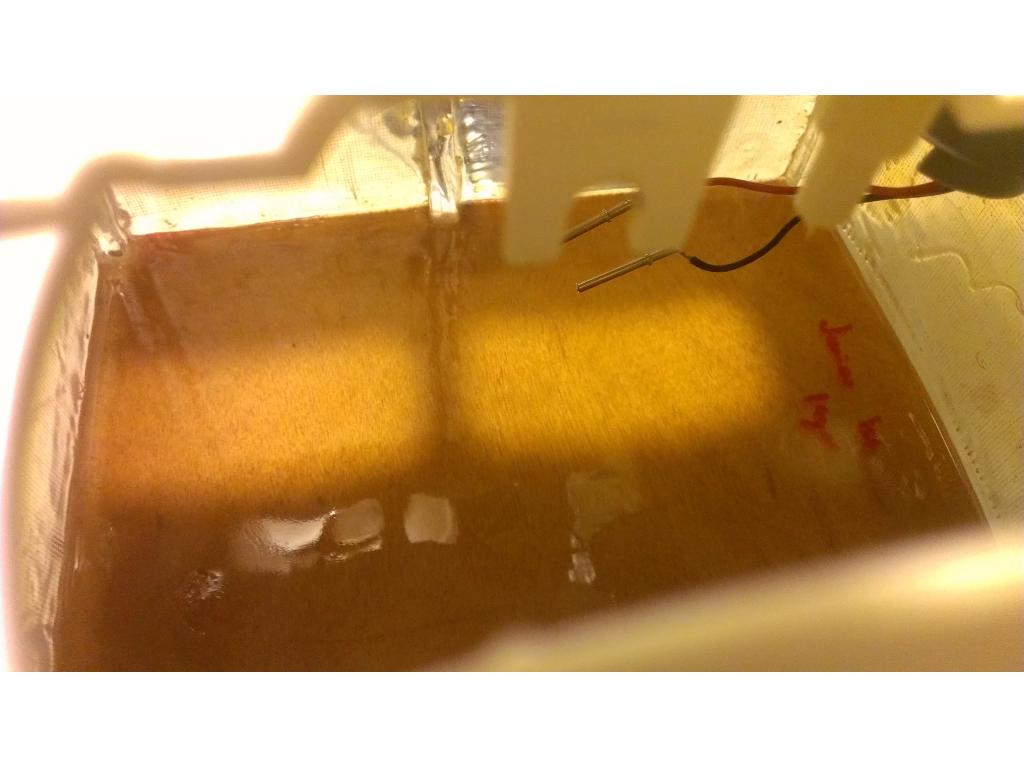
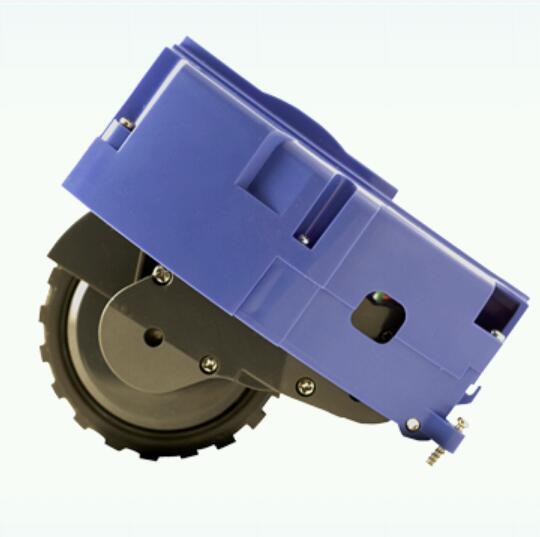
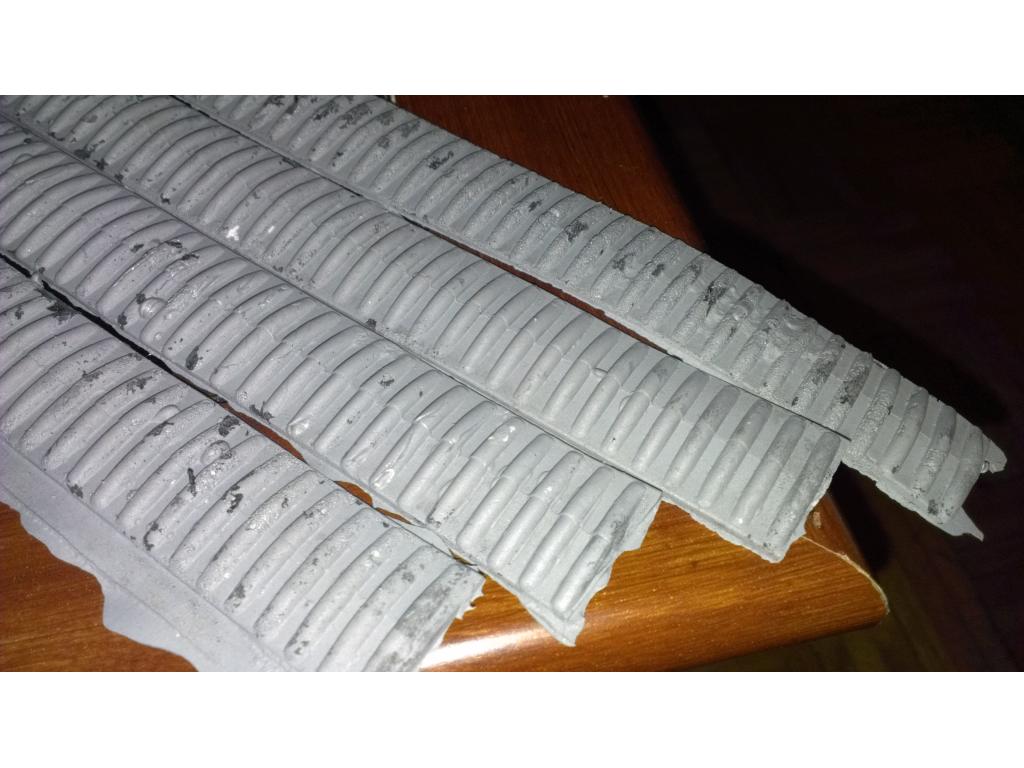
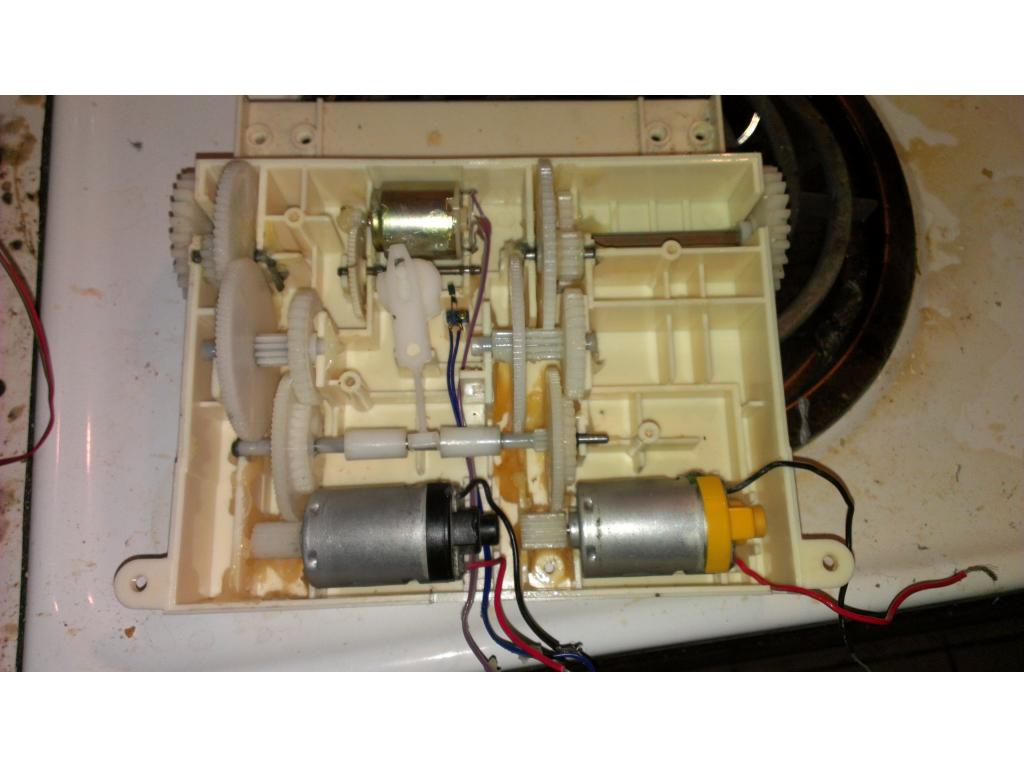
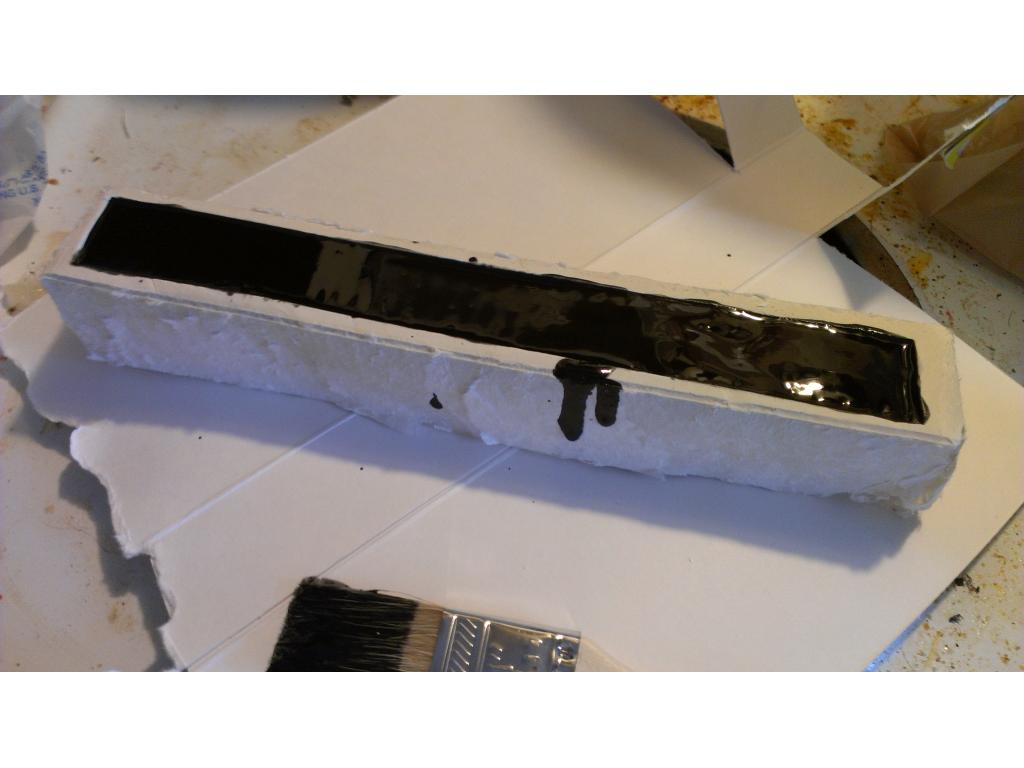
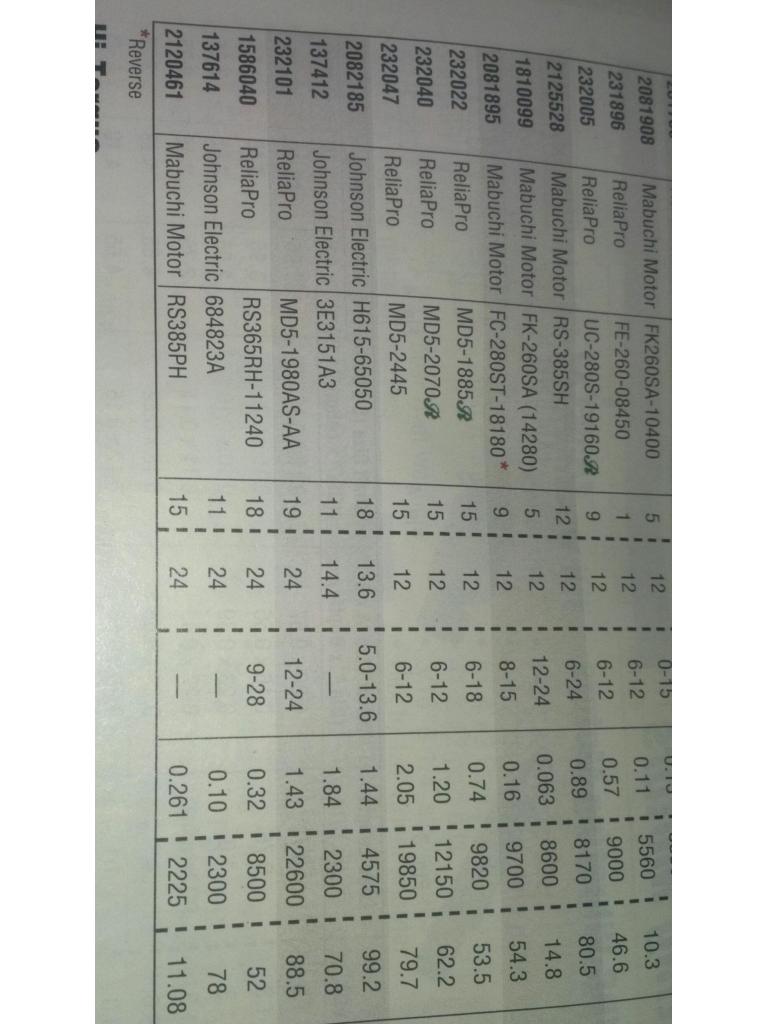
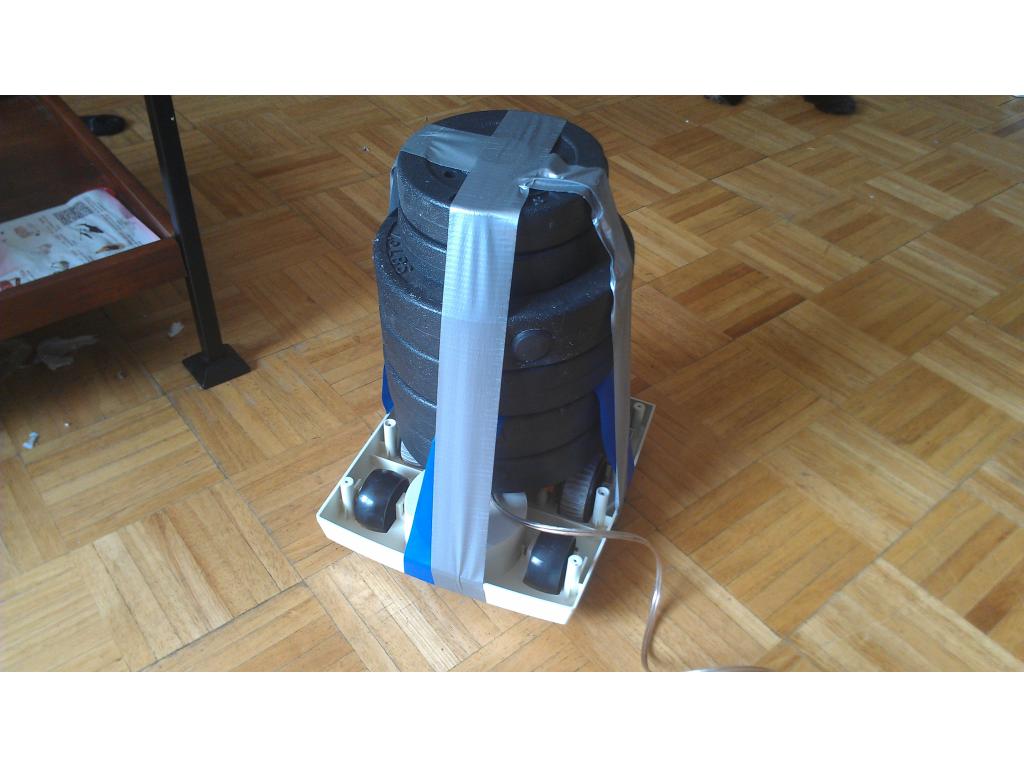
I tried spot gliding with plastic epoxy to affix the axles. But..... Once I loaded the base down with 40 pounds one wheels started coming loose. Soooooo I made formers and filled the area with a cup of fiberglass resin. Once this cures it should be hard as a rock and hold the axles in place. Let's all cross.our.fingers in a few.minutes I can bolt in the gearbox and test the.movement with weight. Also take mind the first test is low gear , second is high gear.YouTube video of Jarvis base in low gear. I have noticed noise significantly drops at 6 volts but it still has tons of torque. https://www.youtube.com/watch?v=viq18XPdSIg&feature=plcp
High gear,.wow this guy can really move. Like a up best walking pace. https://www.youtube.com/watch?v=nqclPdG5FcY&feature=plcp
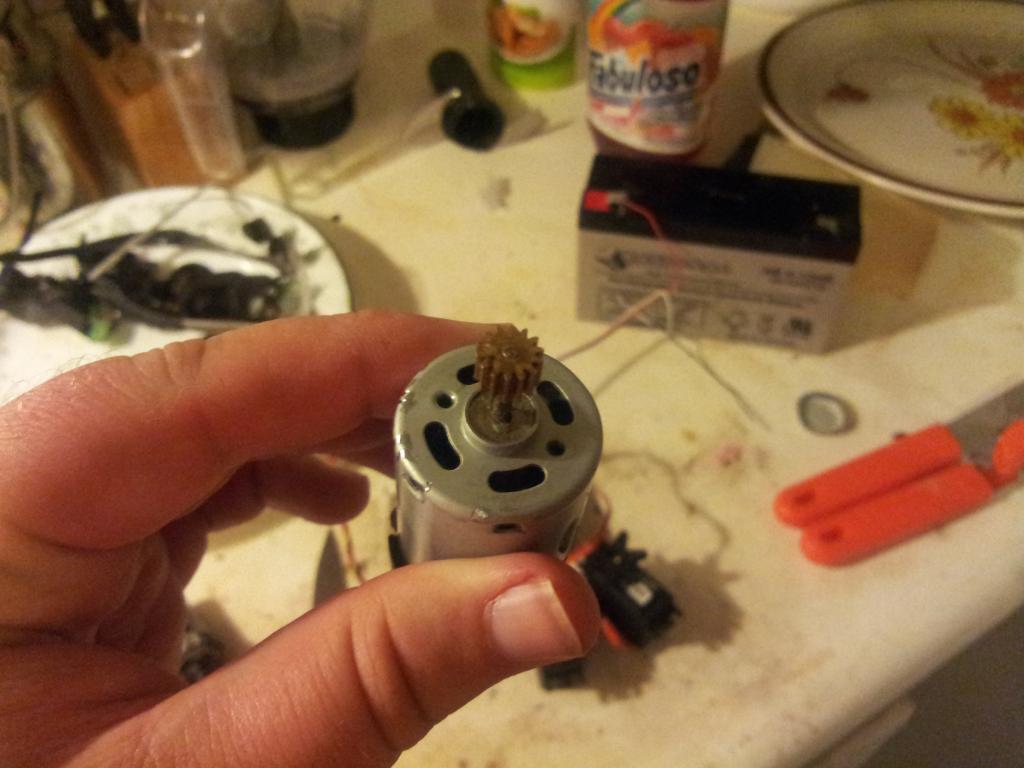
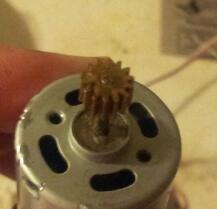
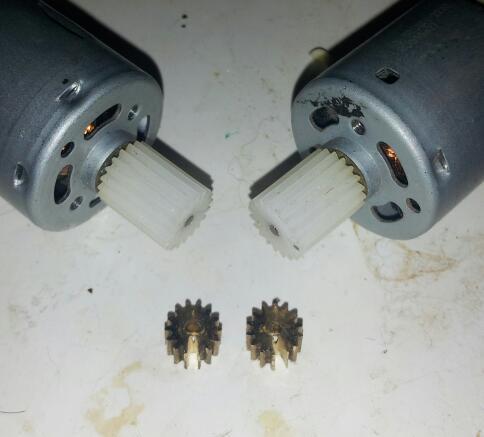
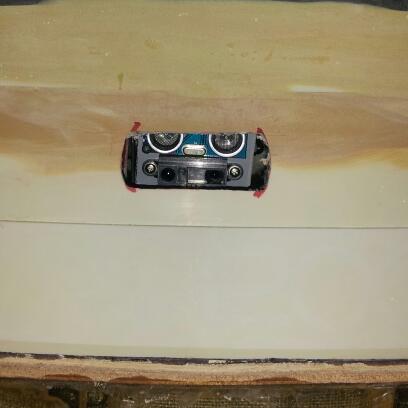
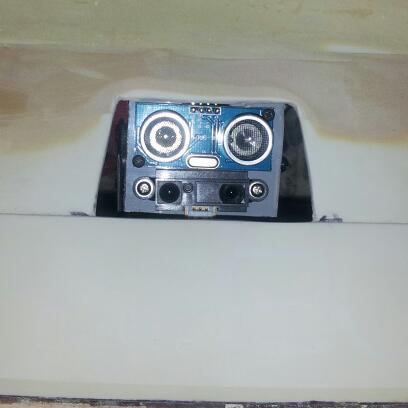
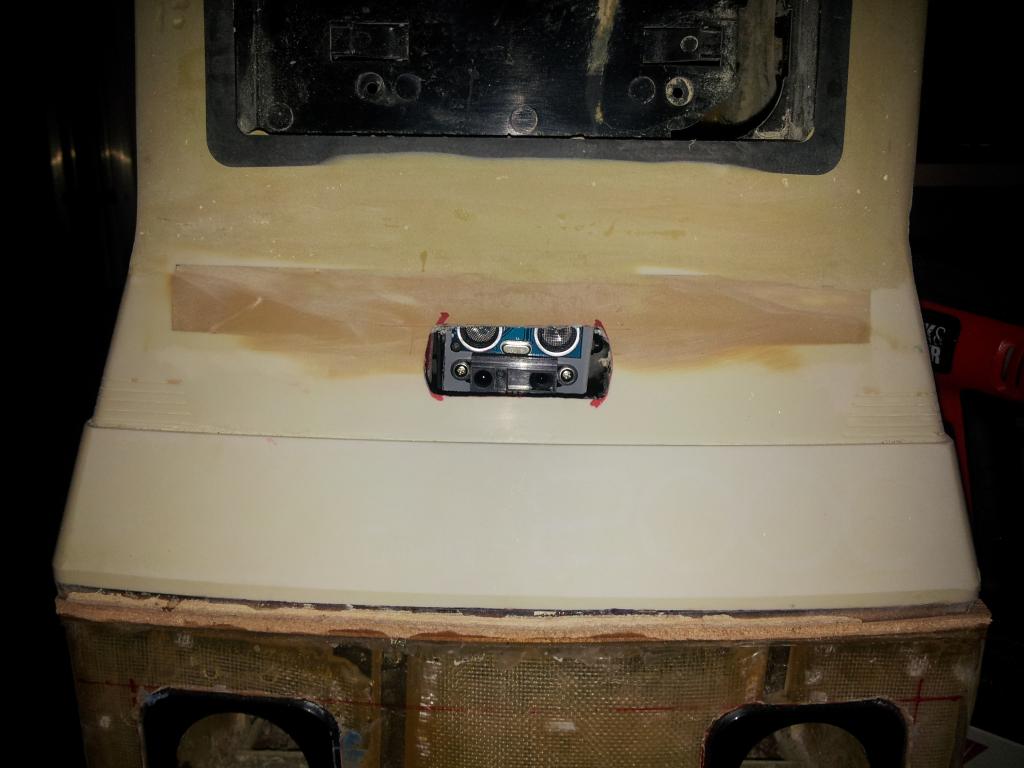
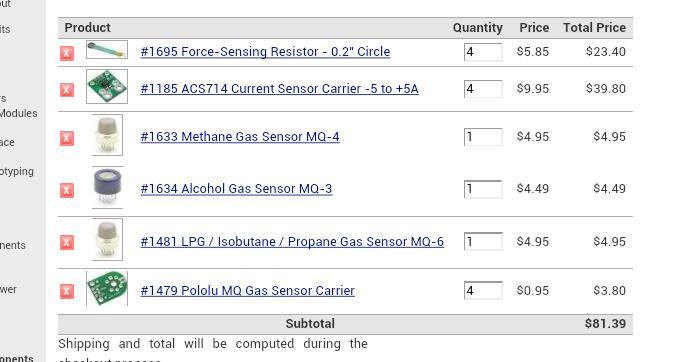
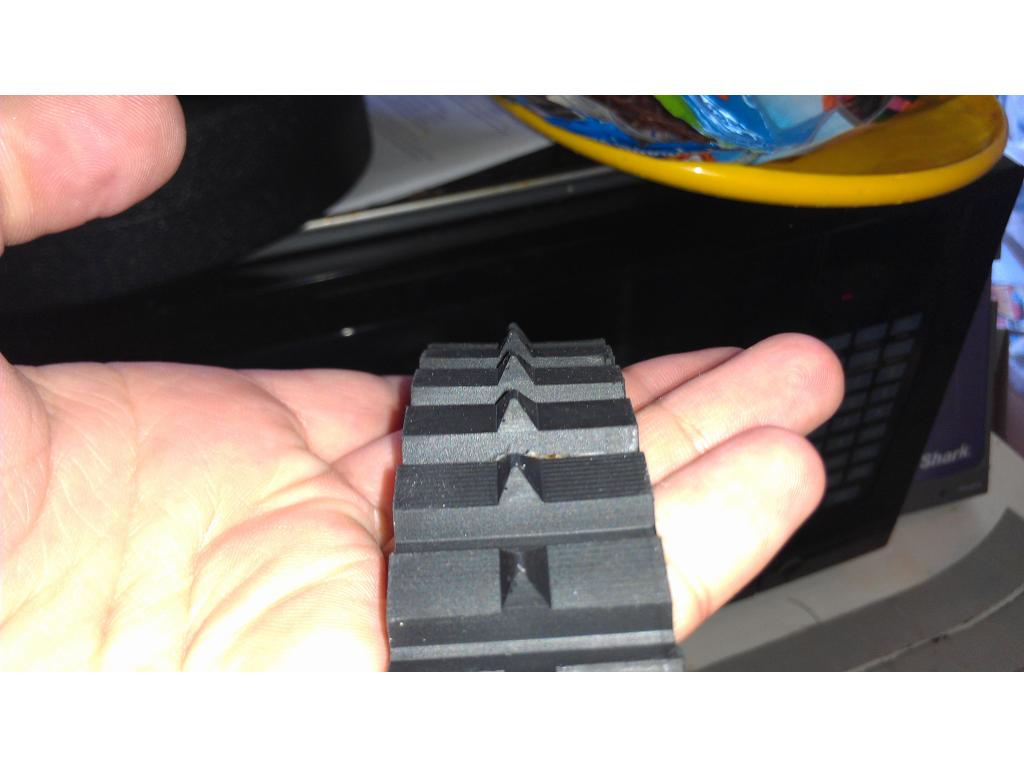
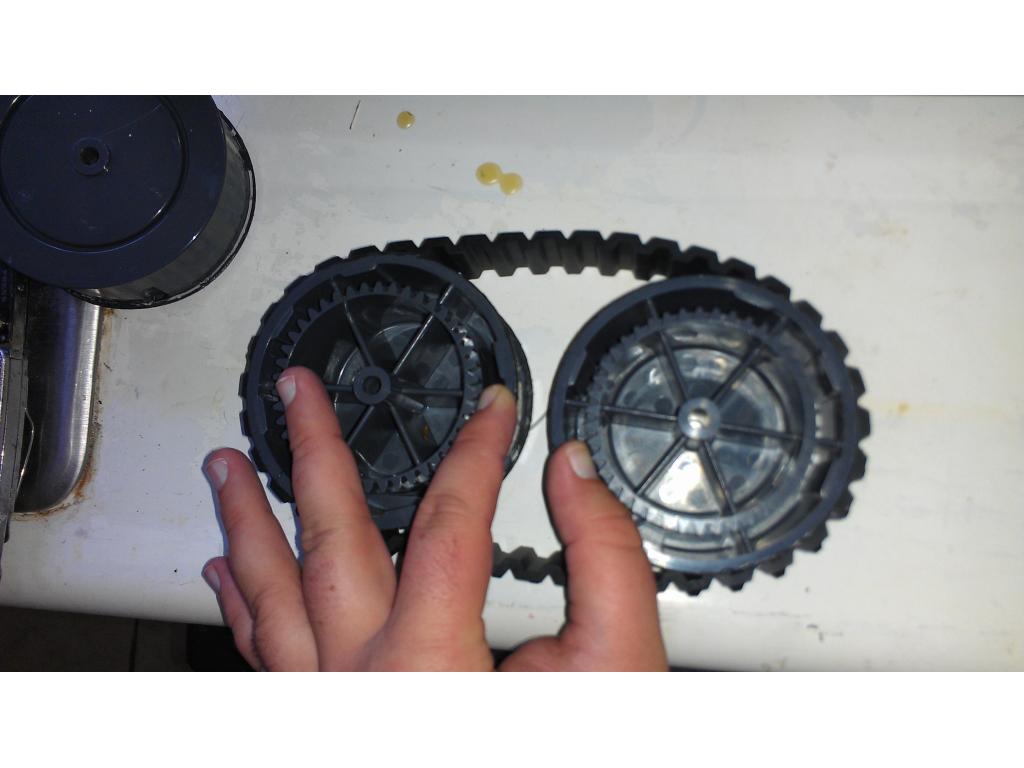
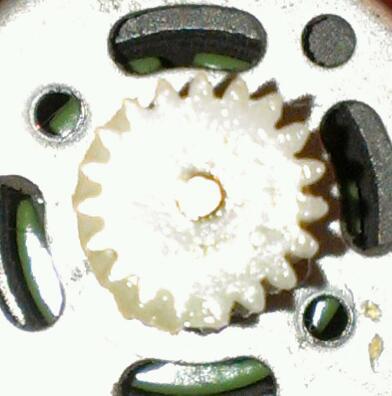
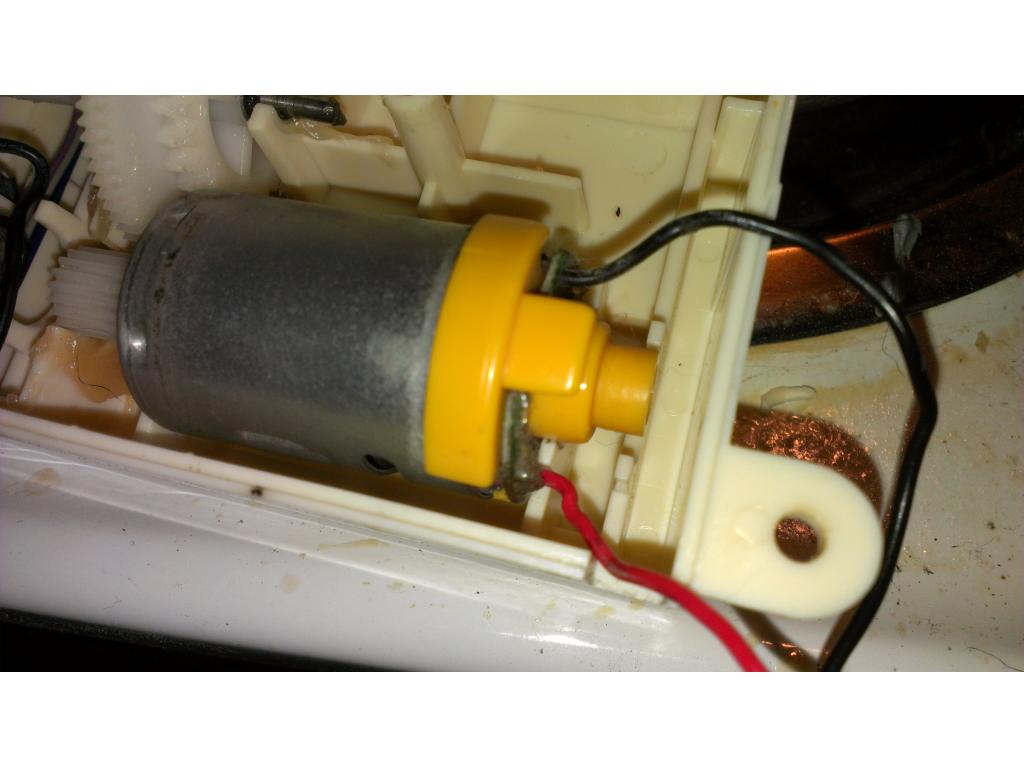
Unless I can really slow Jarvis down on high gear I think my only choice will be low gear. If I had my choice I would like it to move twice as fast as you saw in low gear. IM super happy it's strong but my only issue is I really need some sensitive way to stop him if he gets caught on something. Because of these super torque motors forget stalling it will just strip the teeth off the gear on the hub.