cE9s4PsOgeBQIORwjd5!~~60_1-634818020230156250.jpg)
Lupuc4g~~60_35-634706297915000000.jpg)
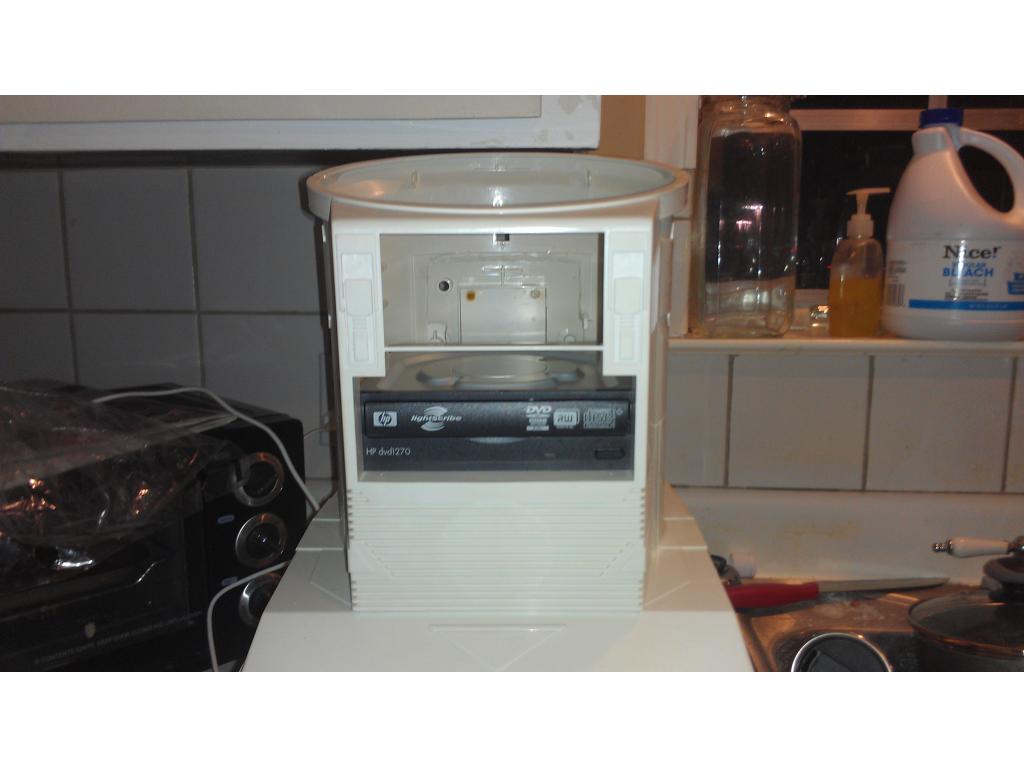
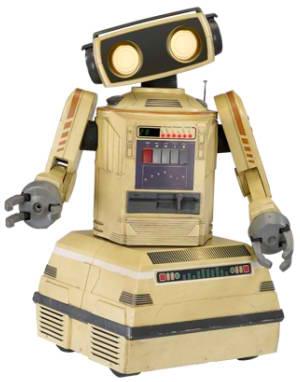
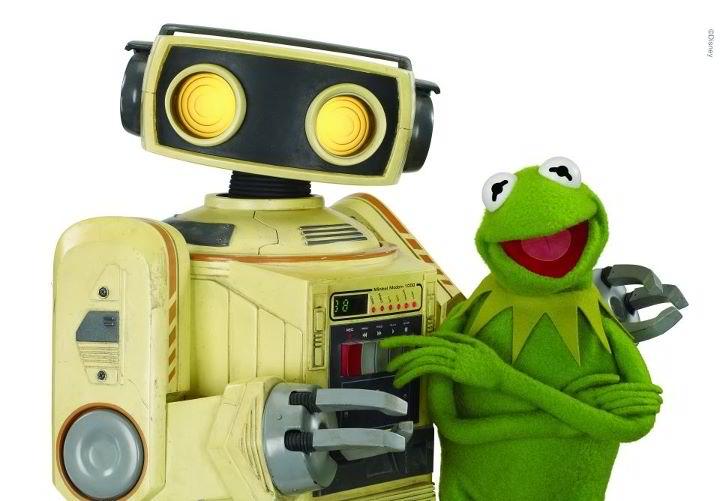
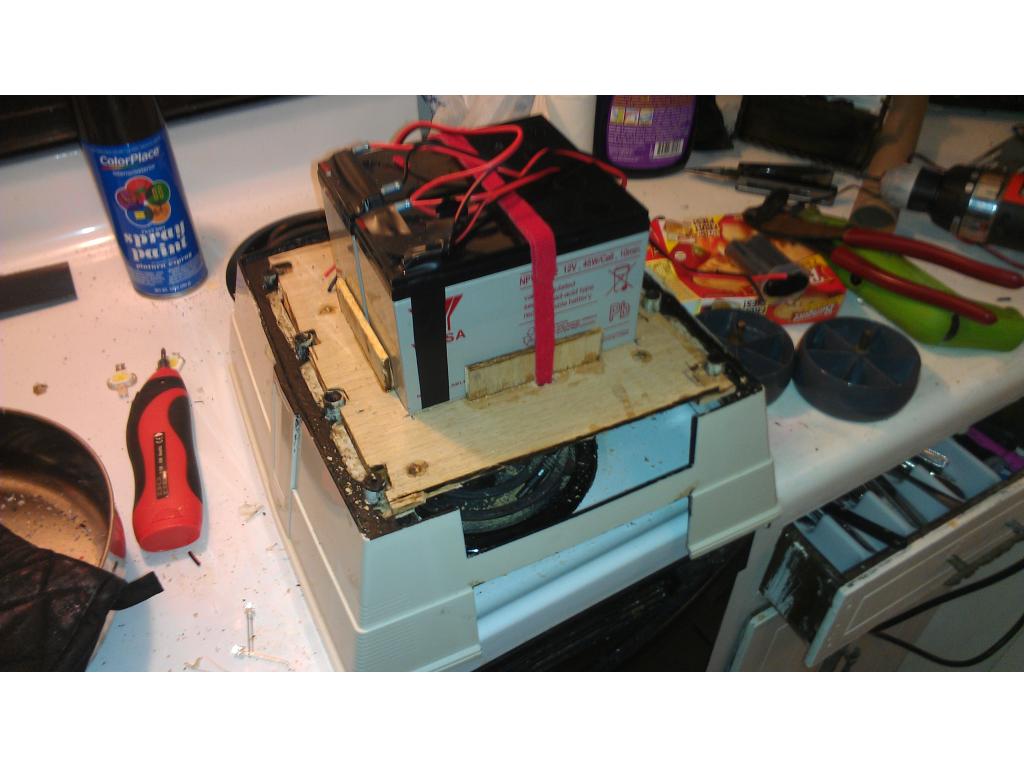
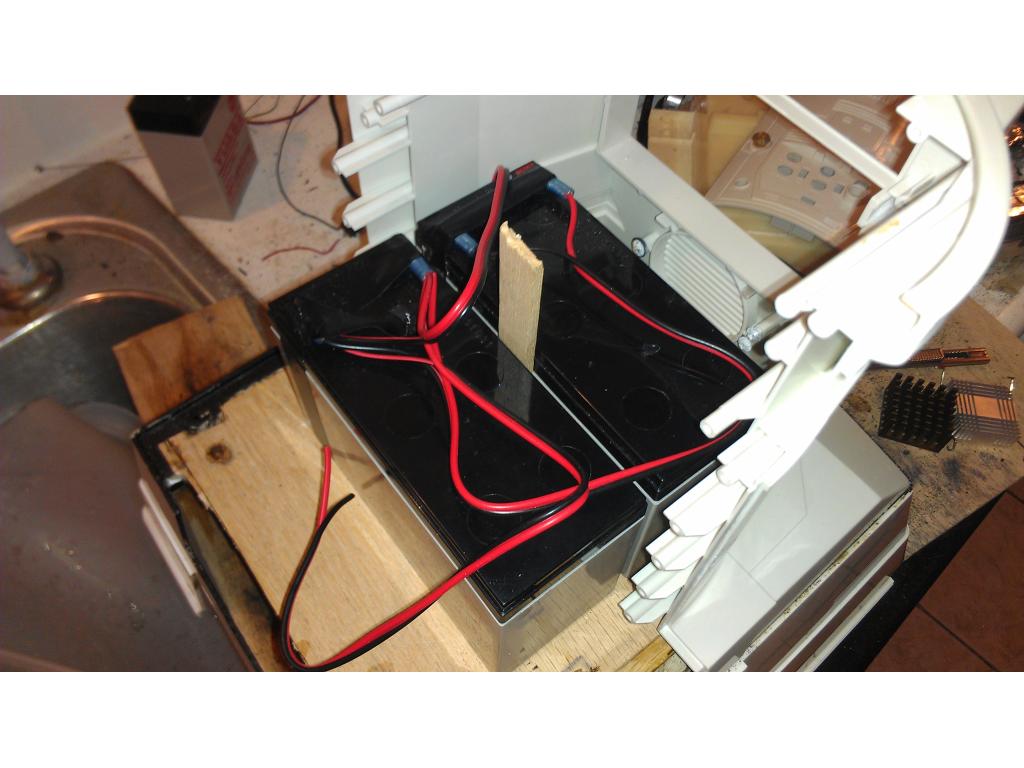
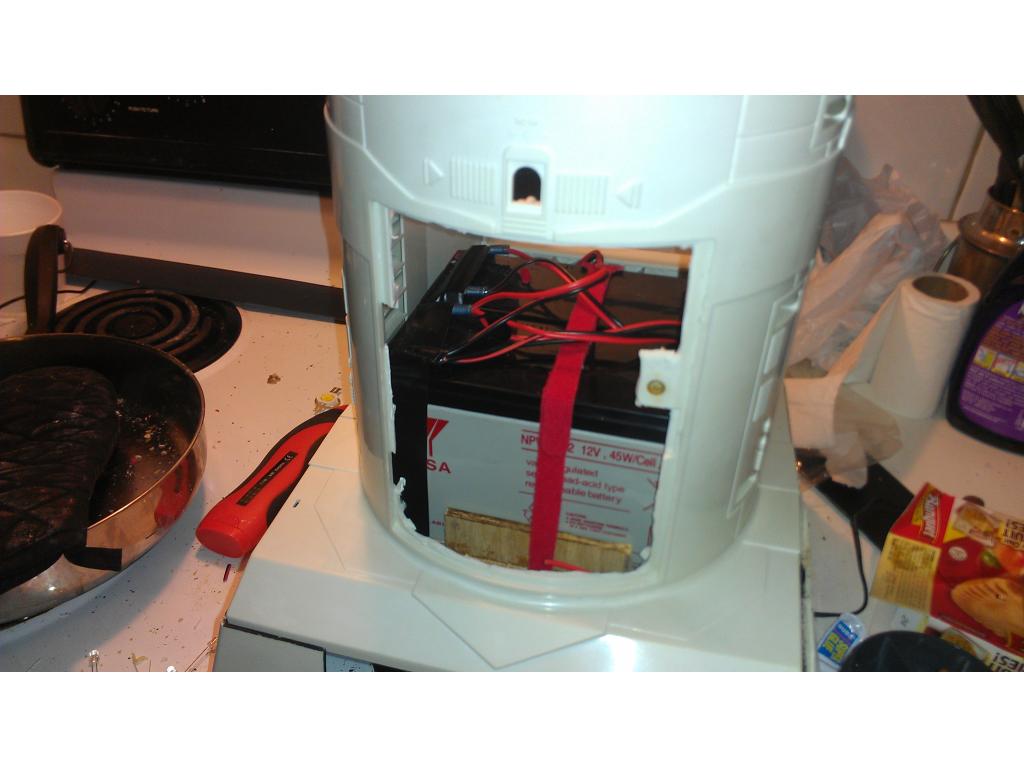
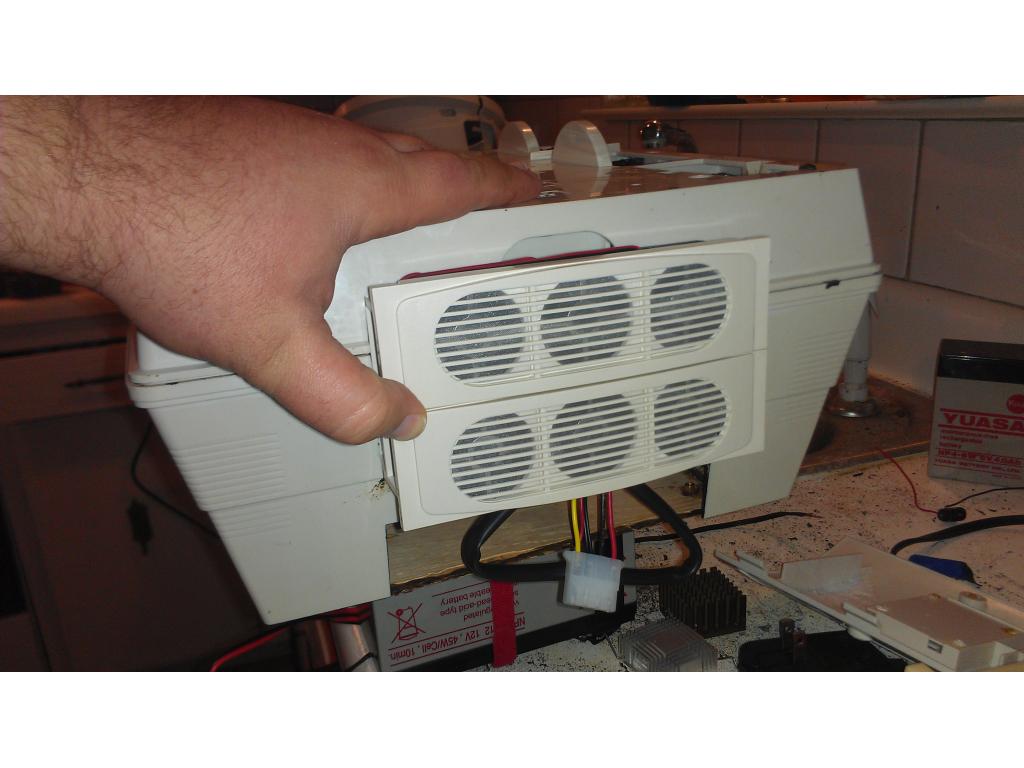
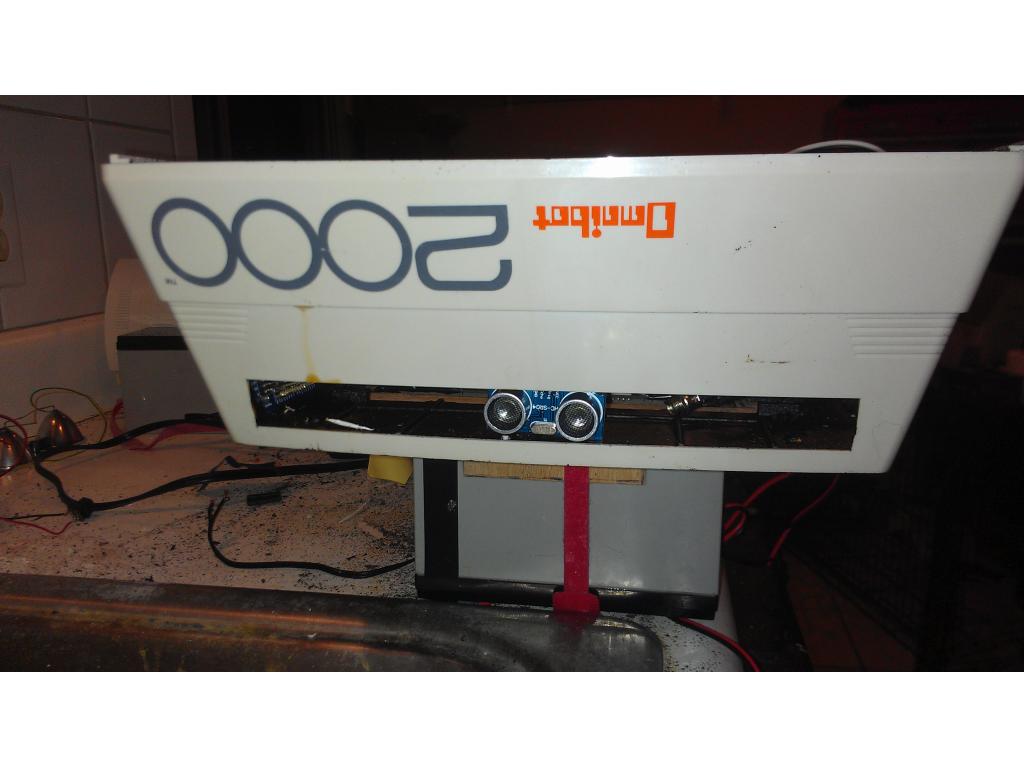
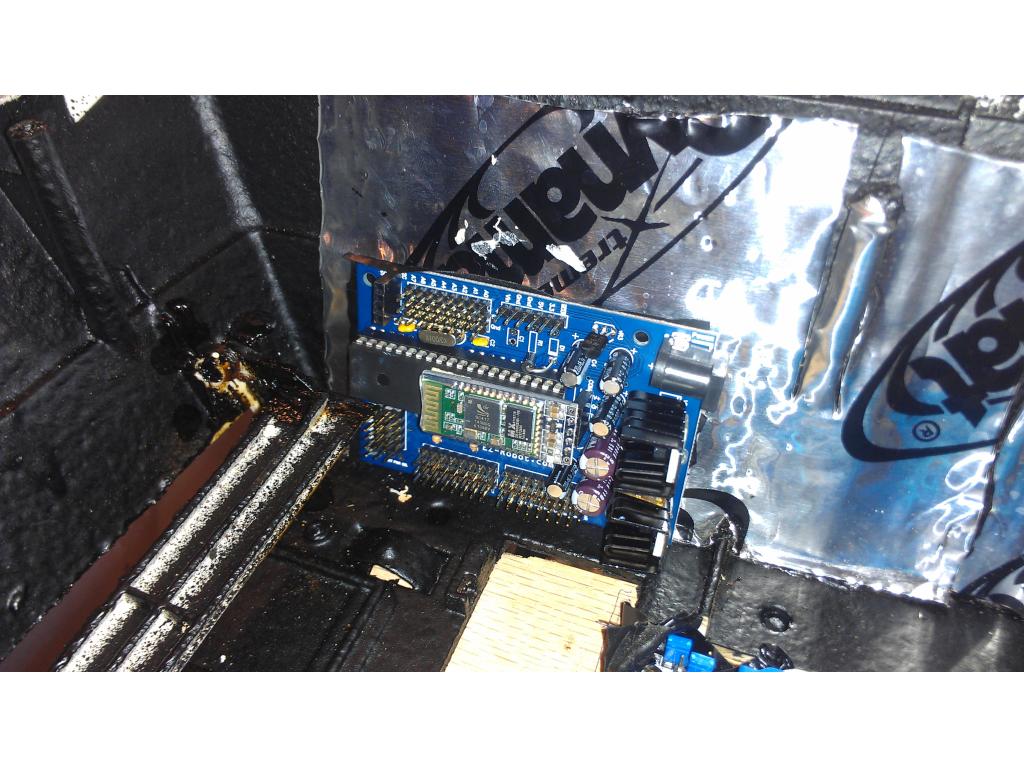
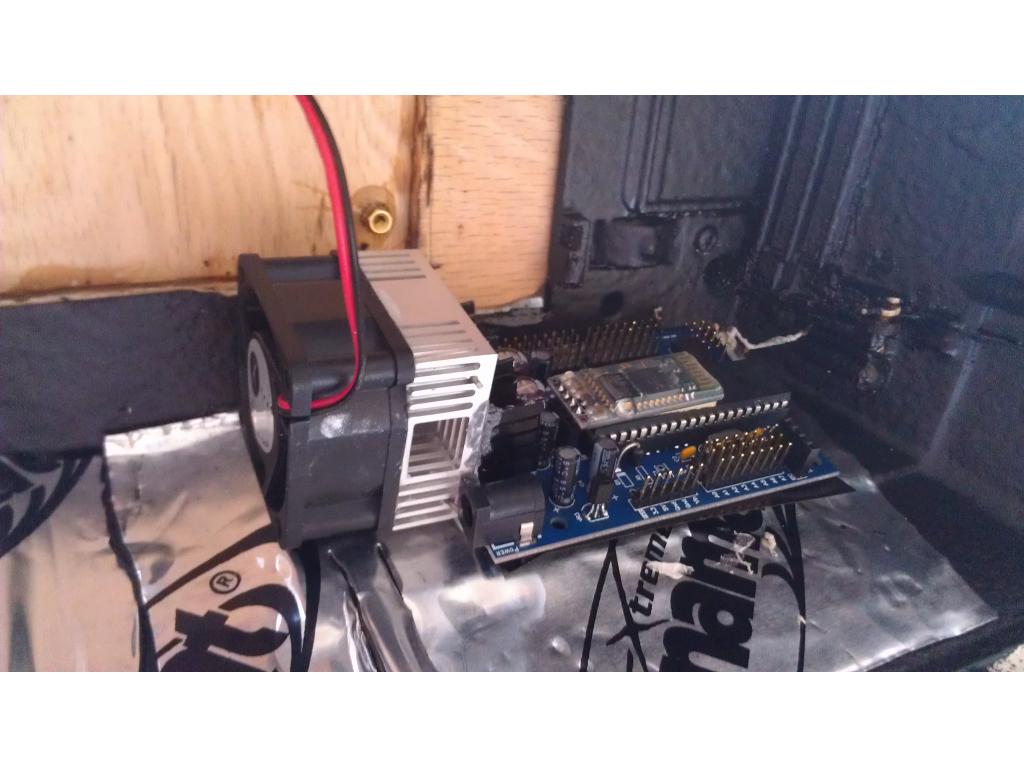
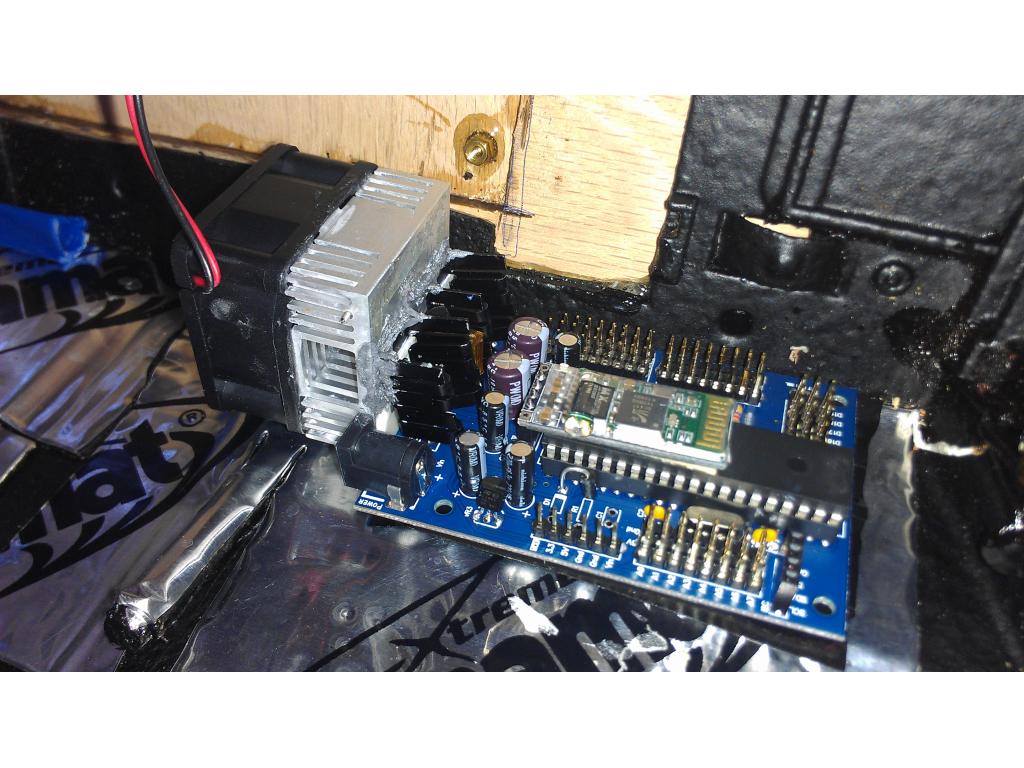
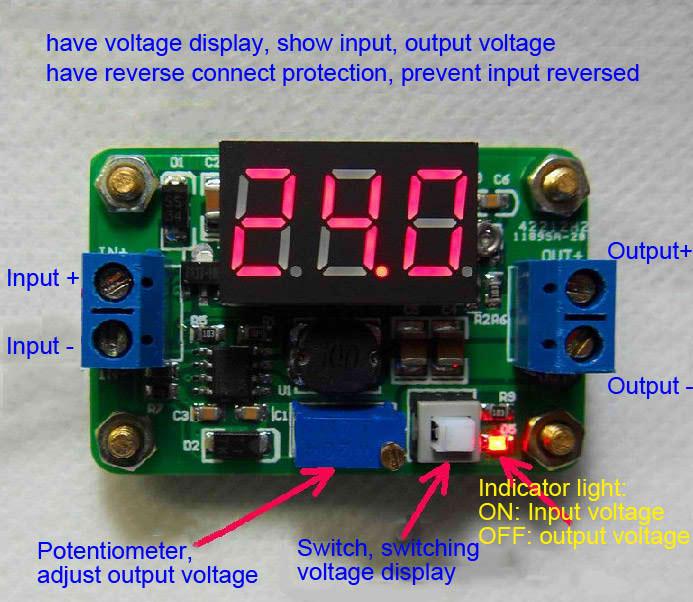
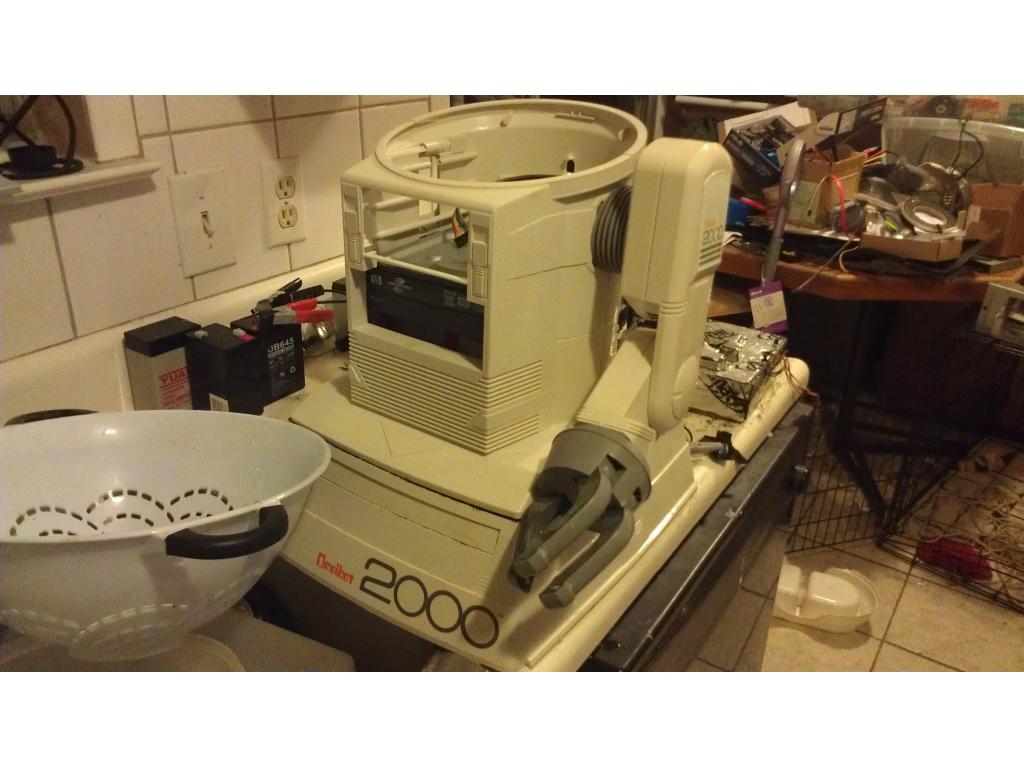
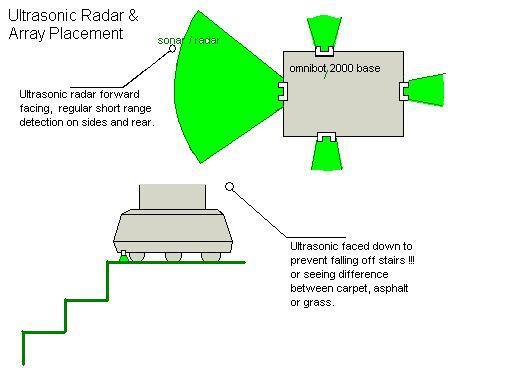
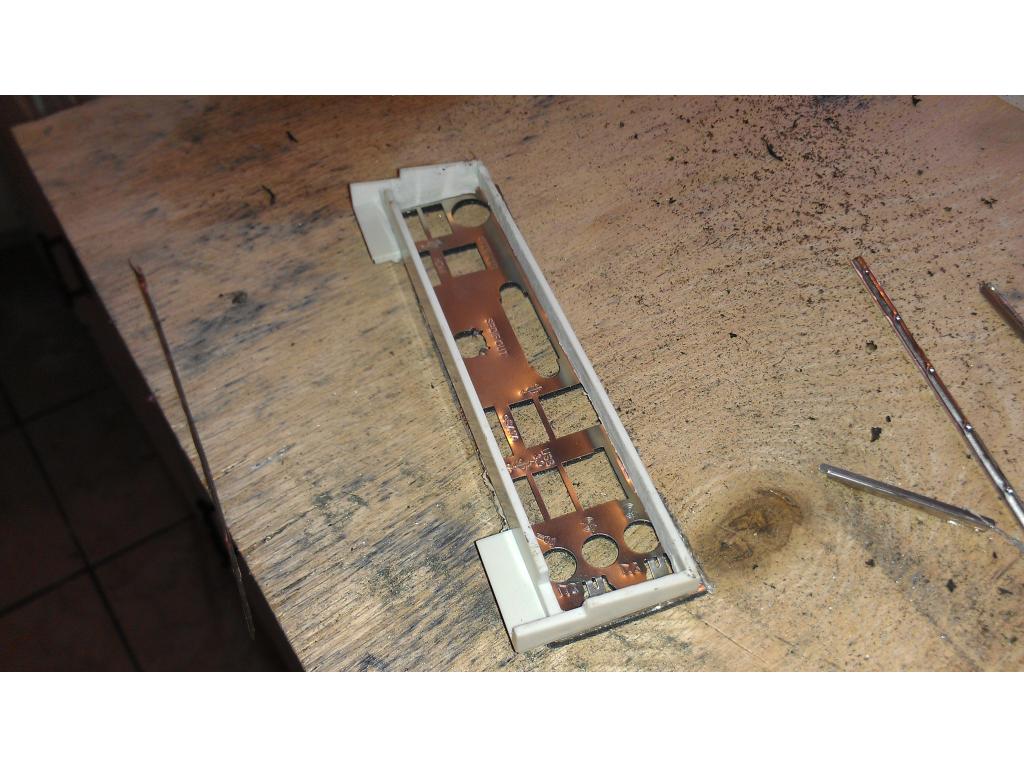
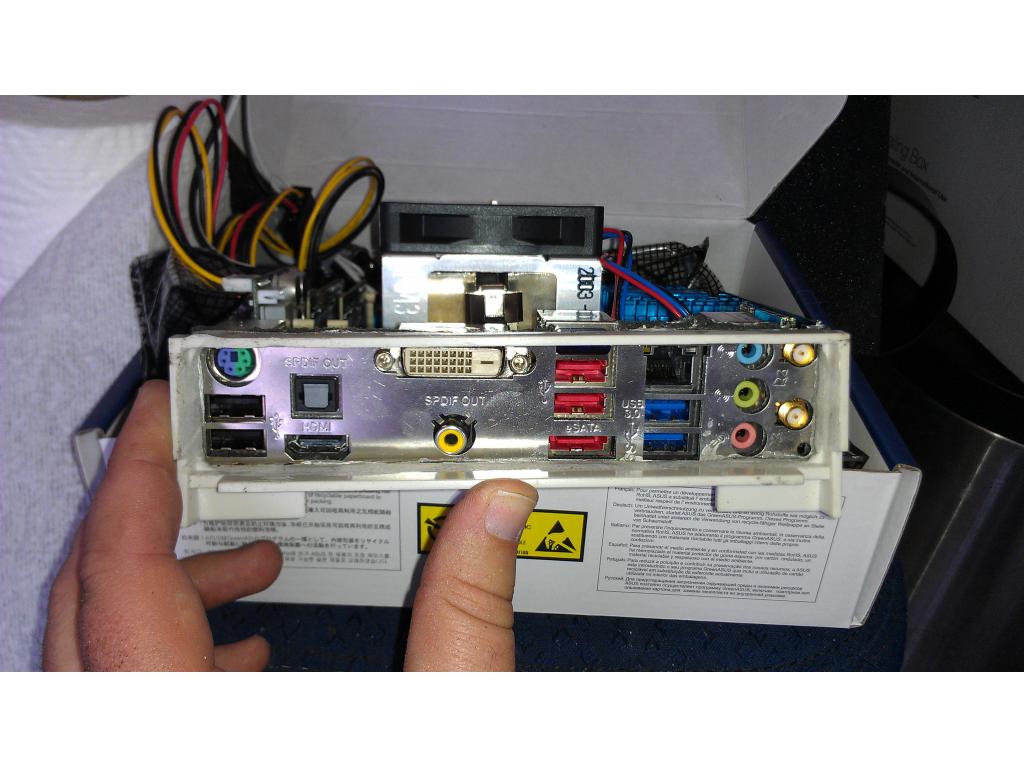
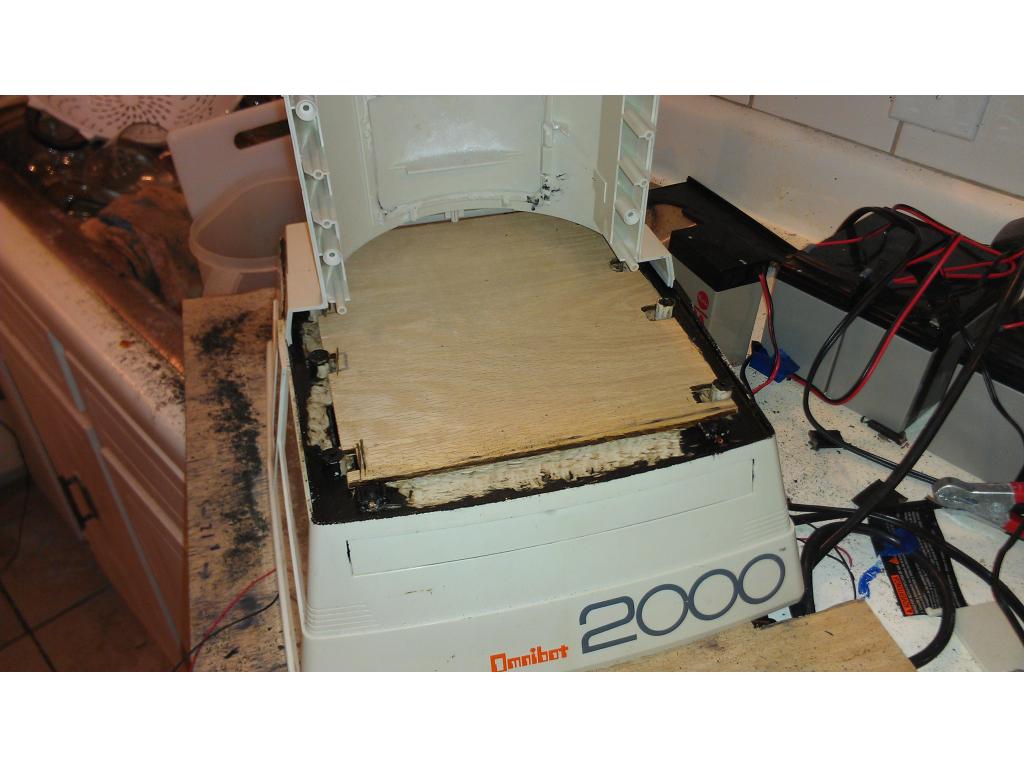
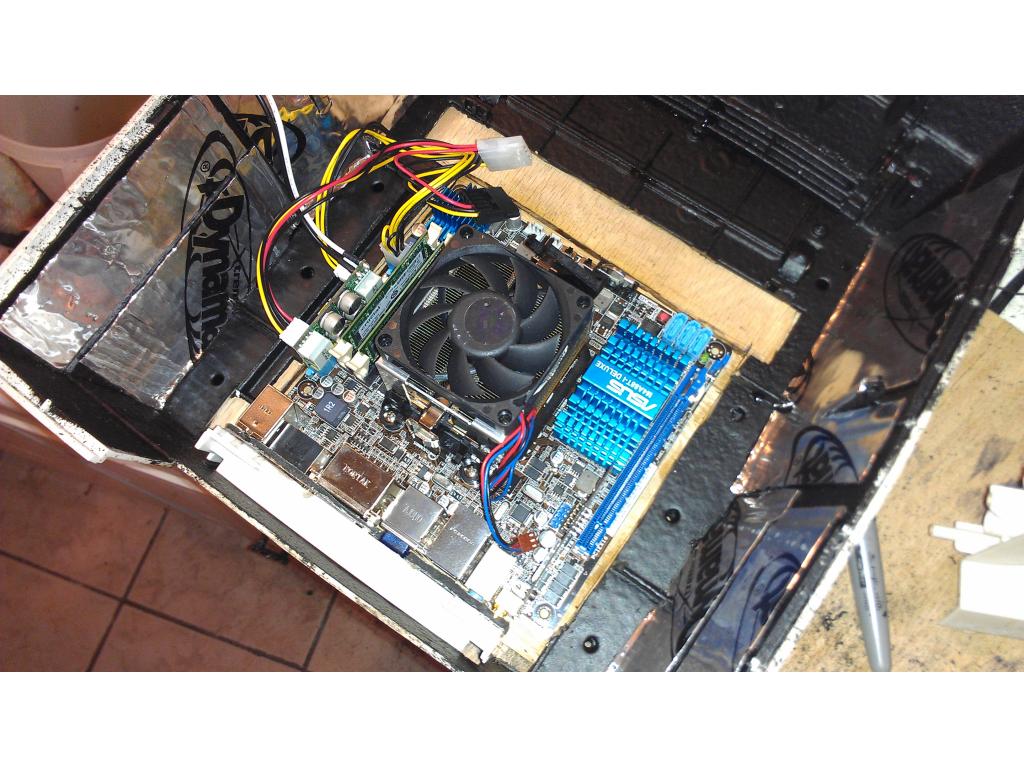
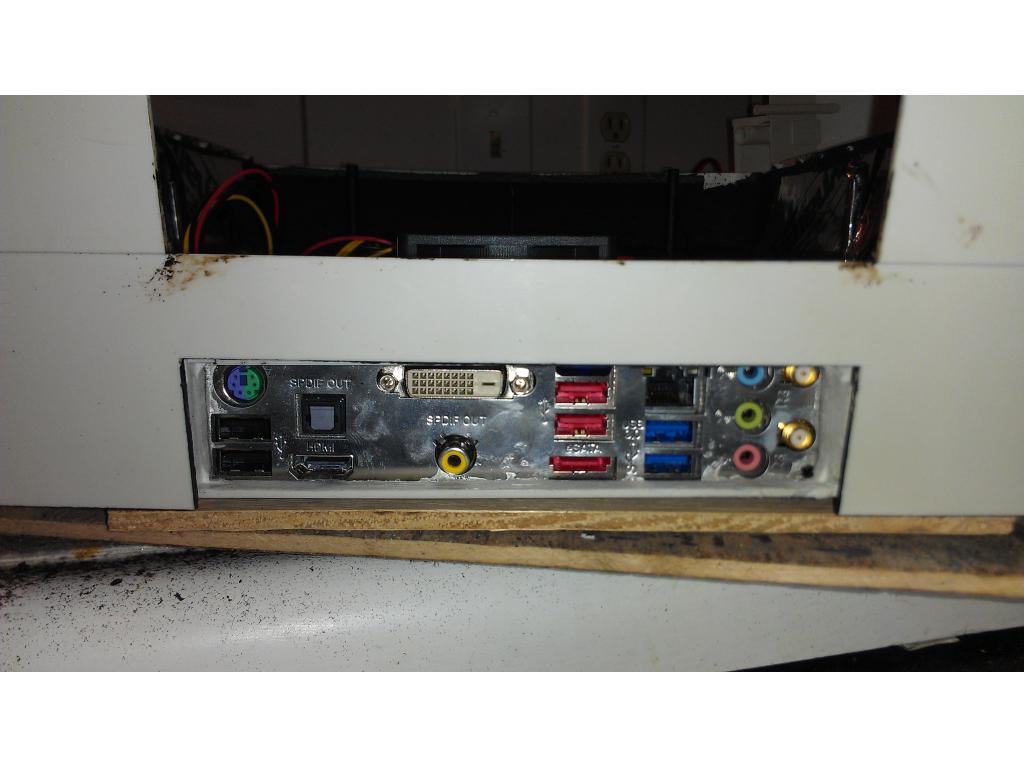
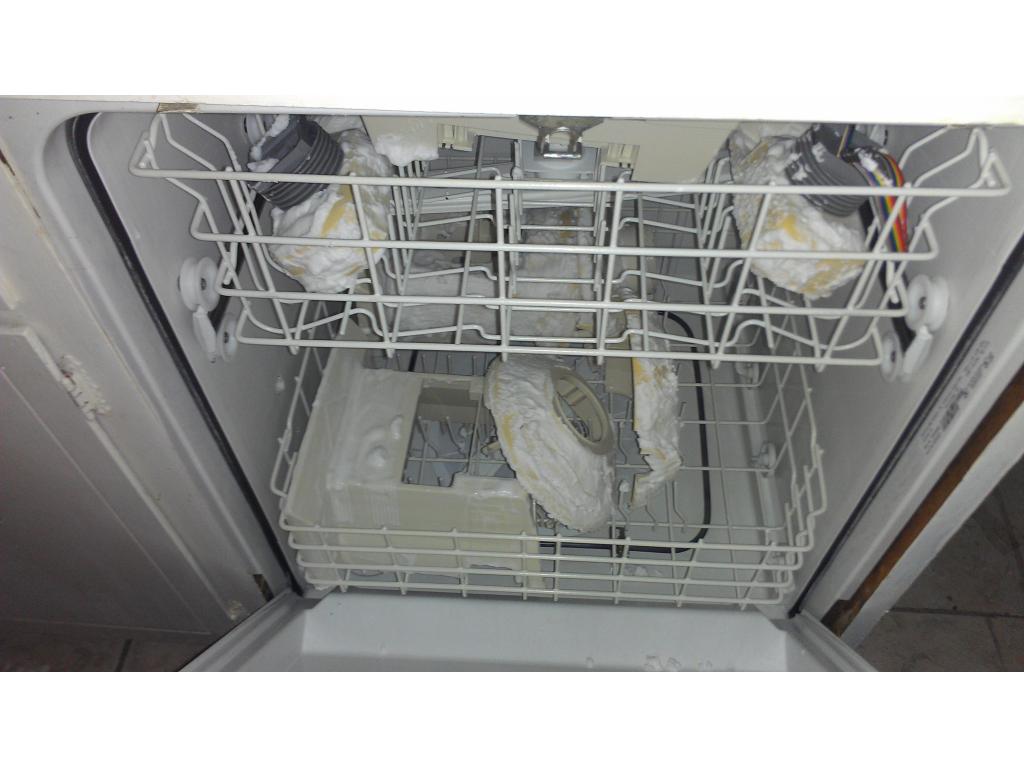
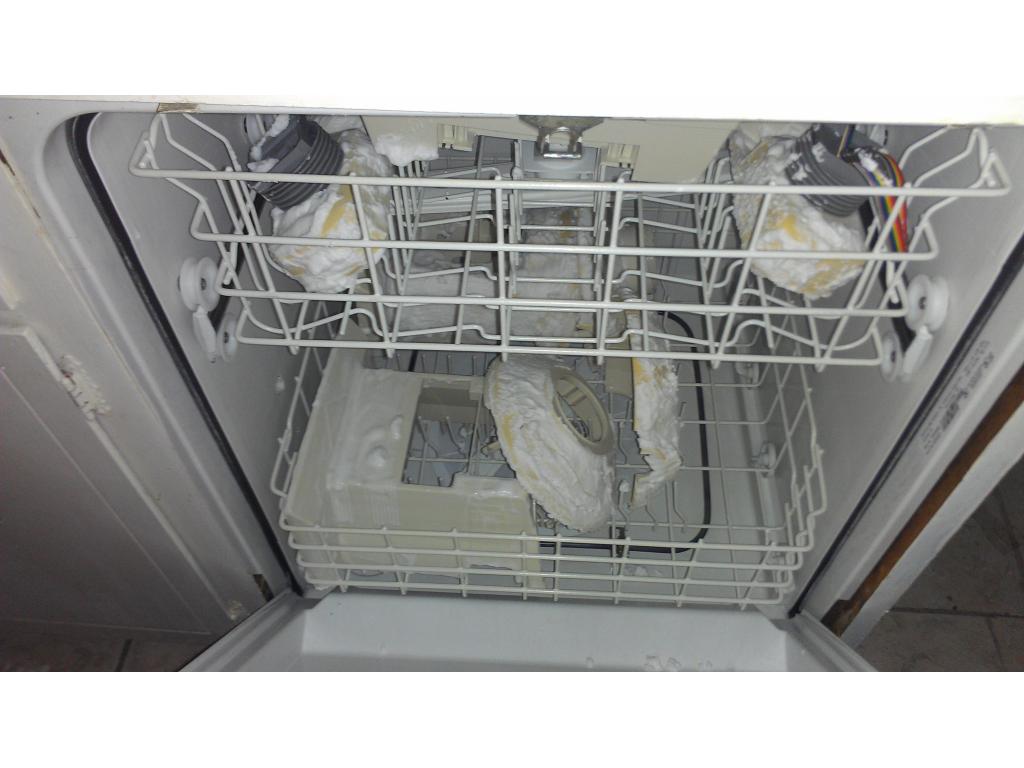
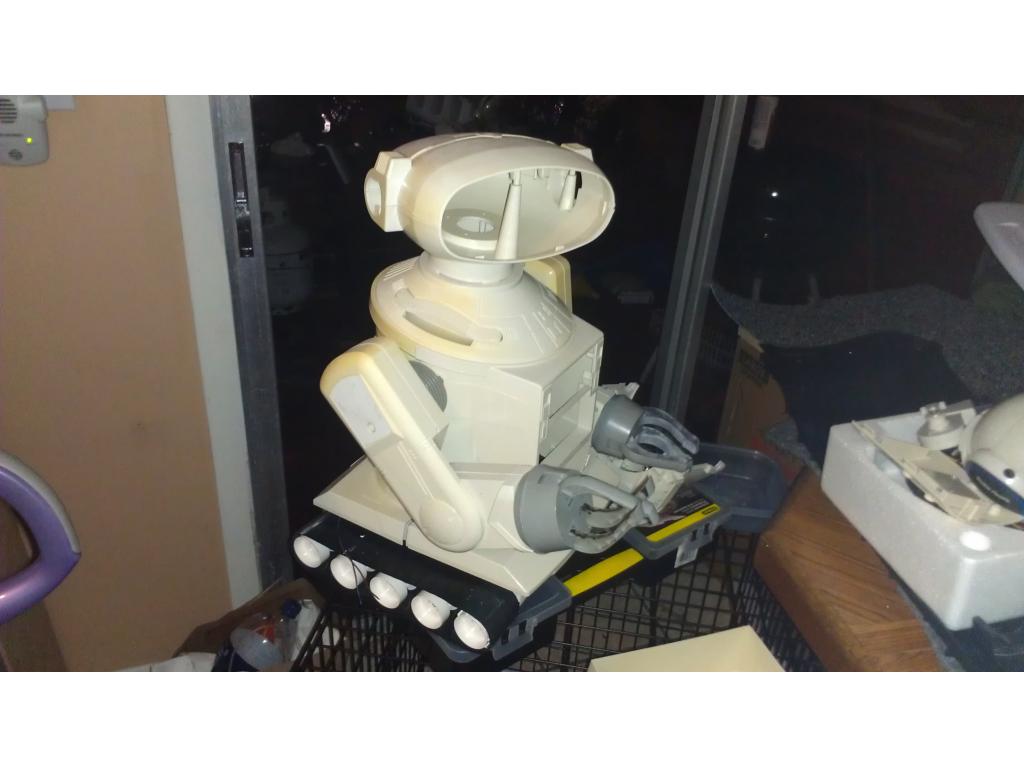
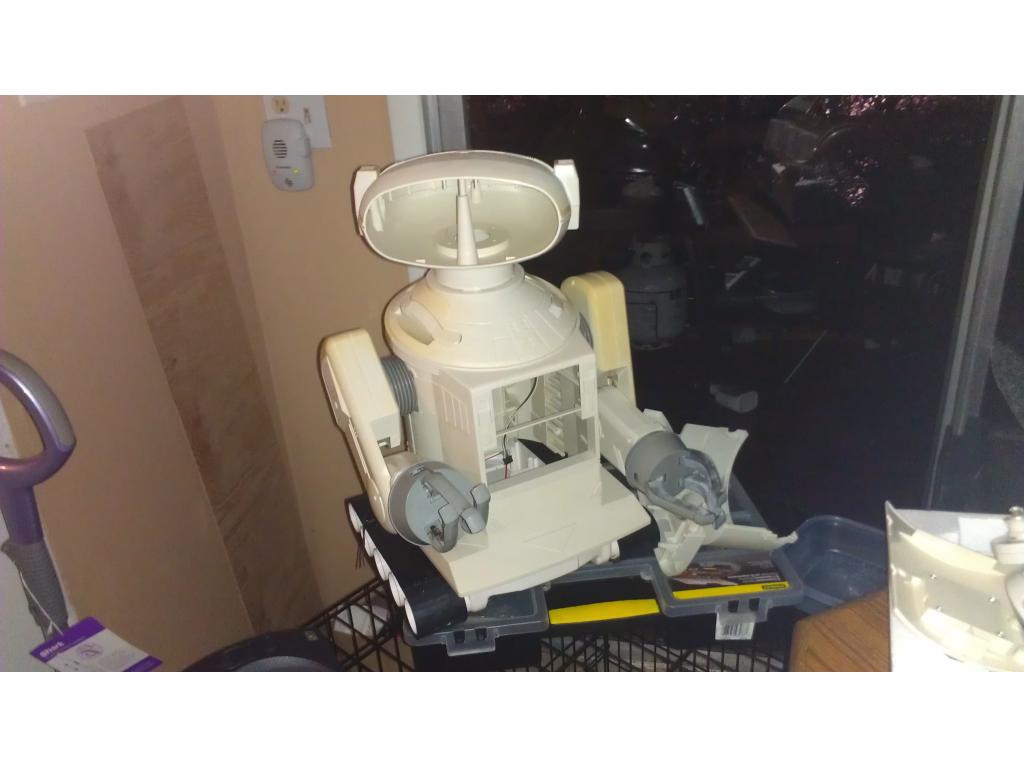
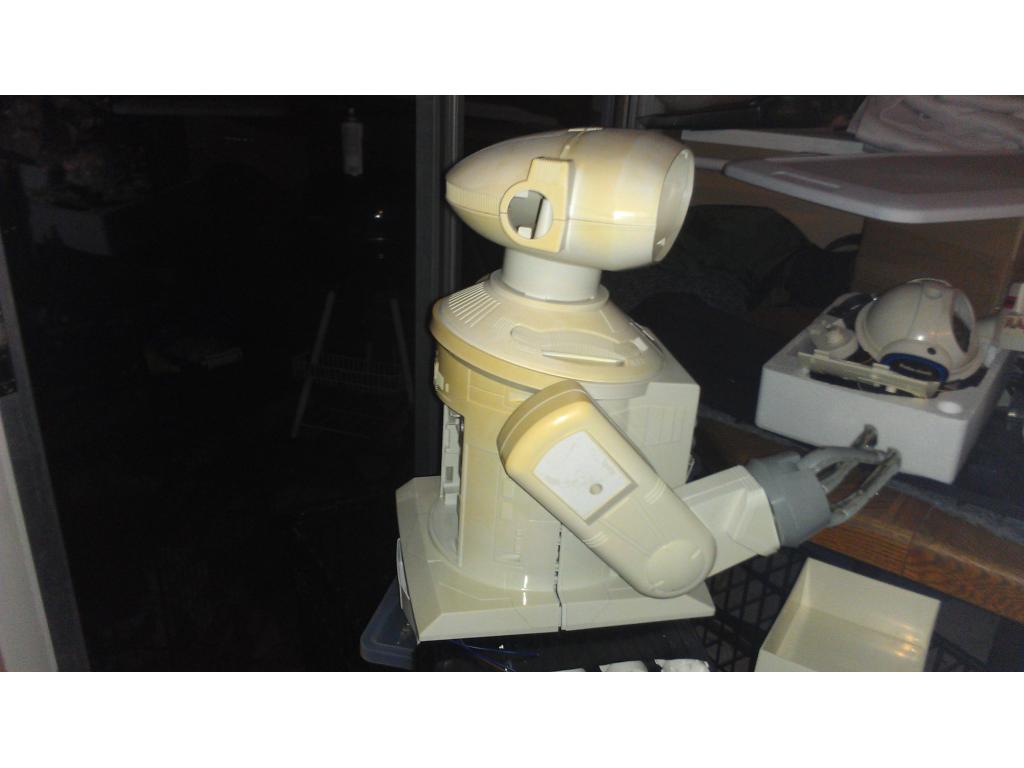
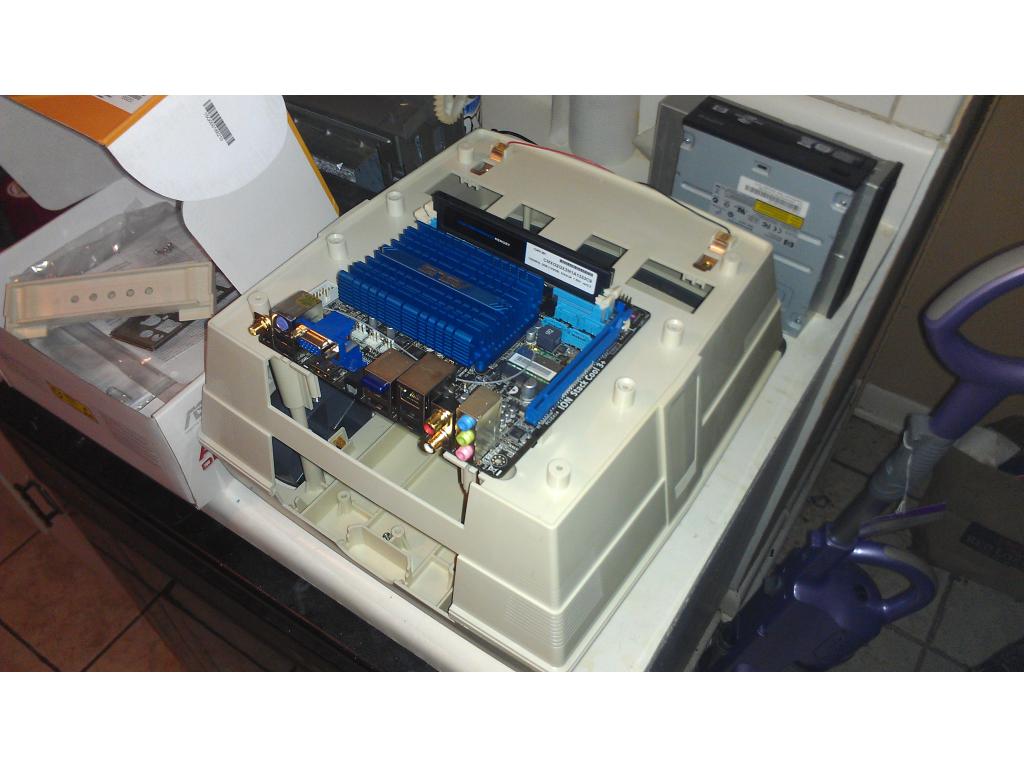
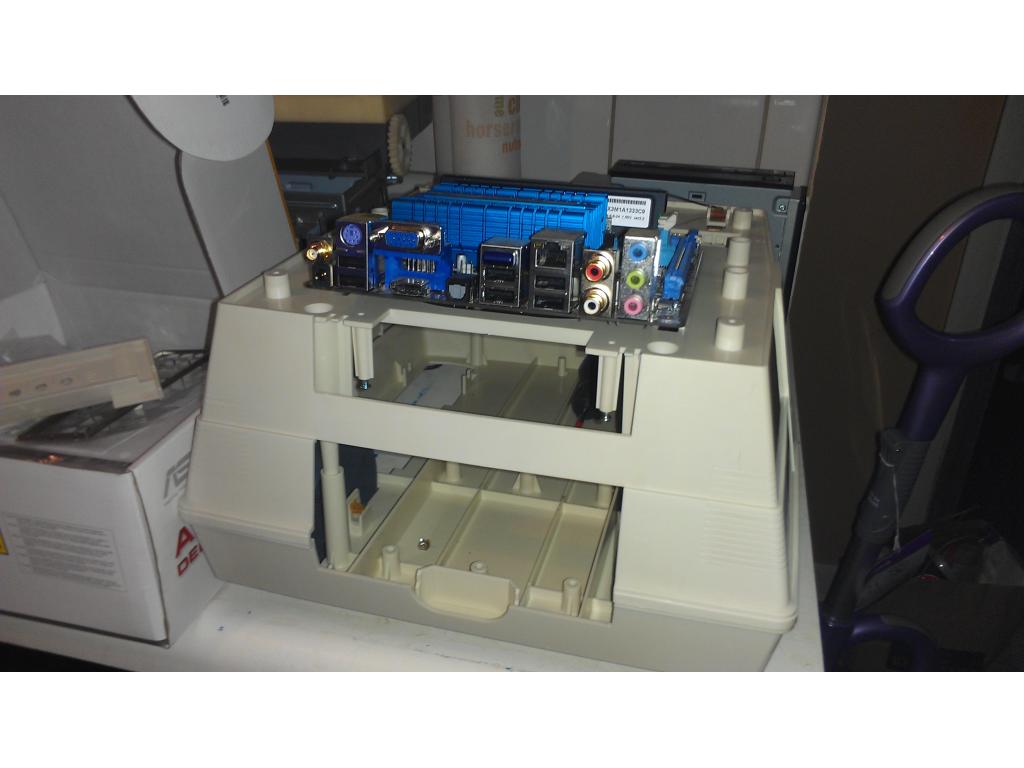
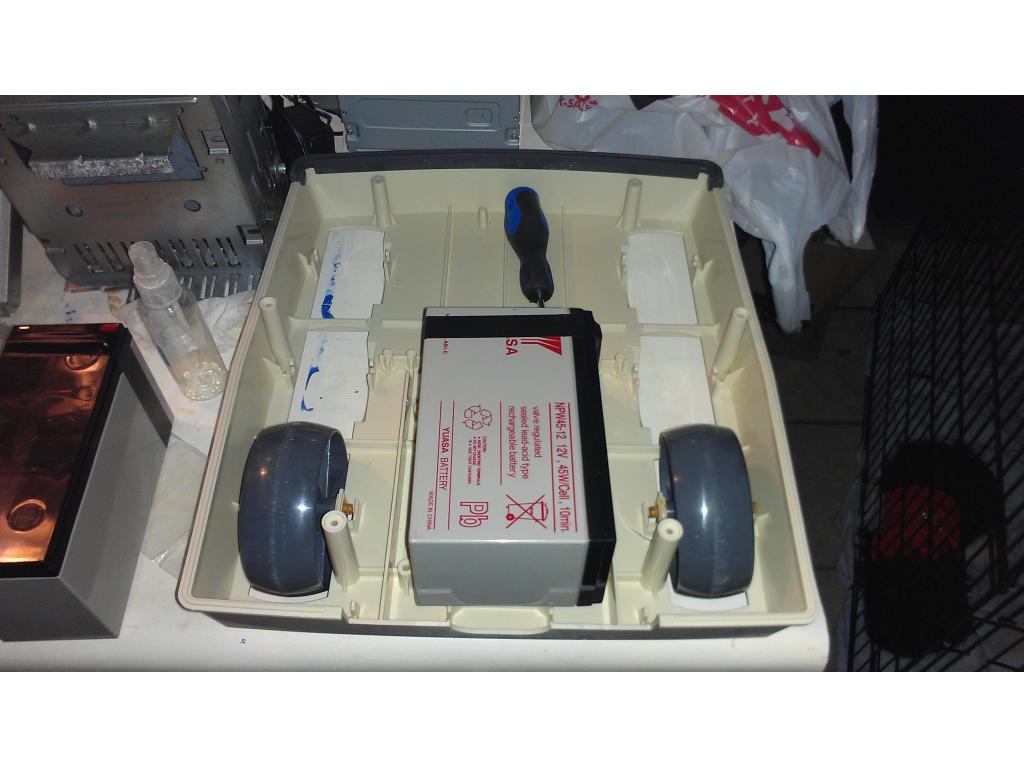
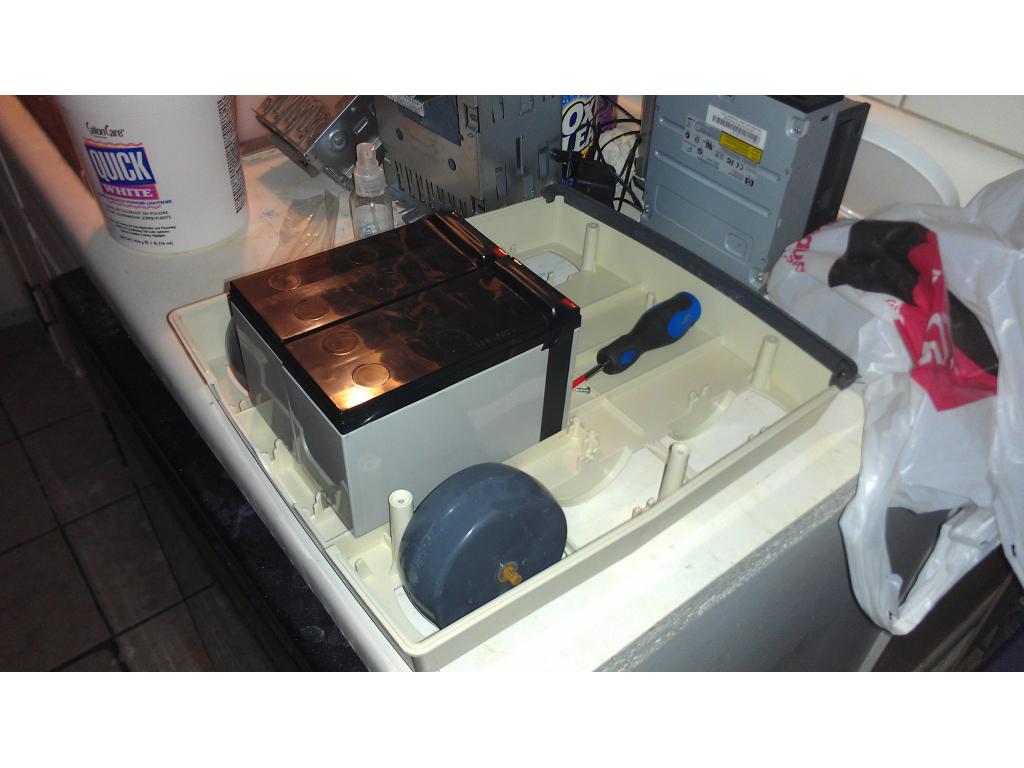
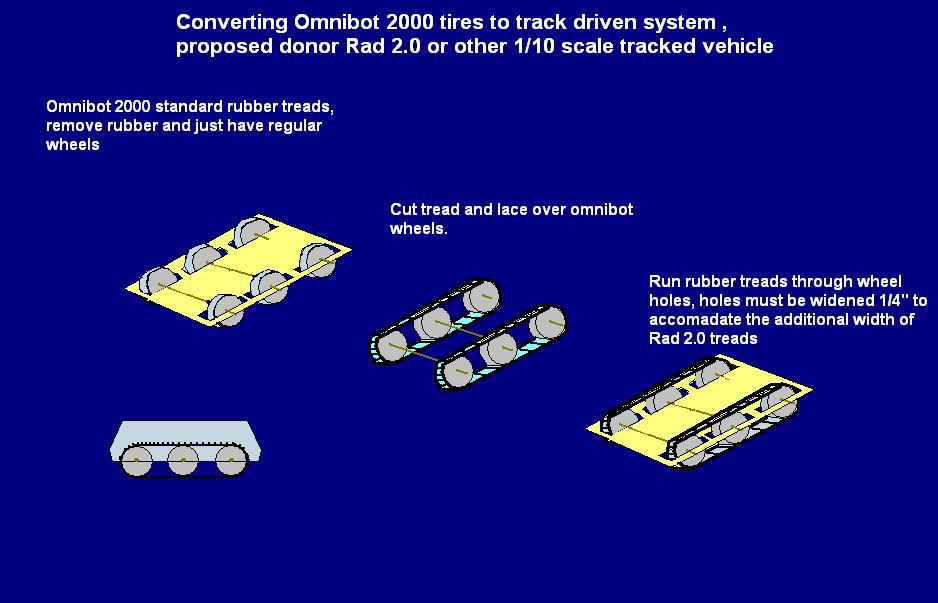


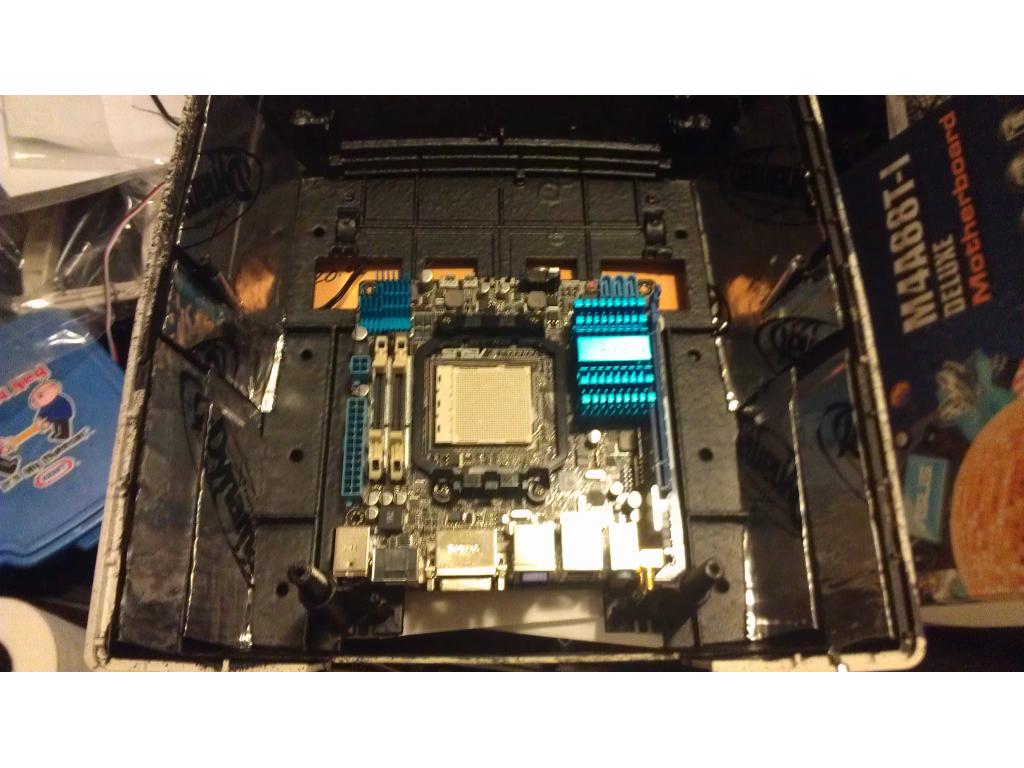
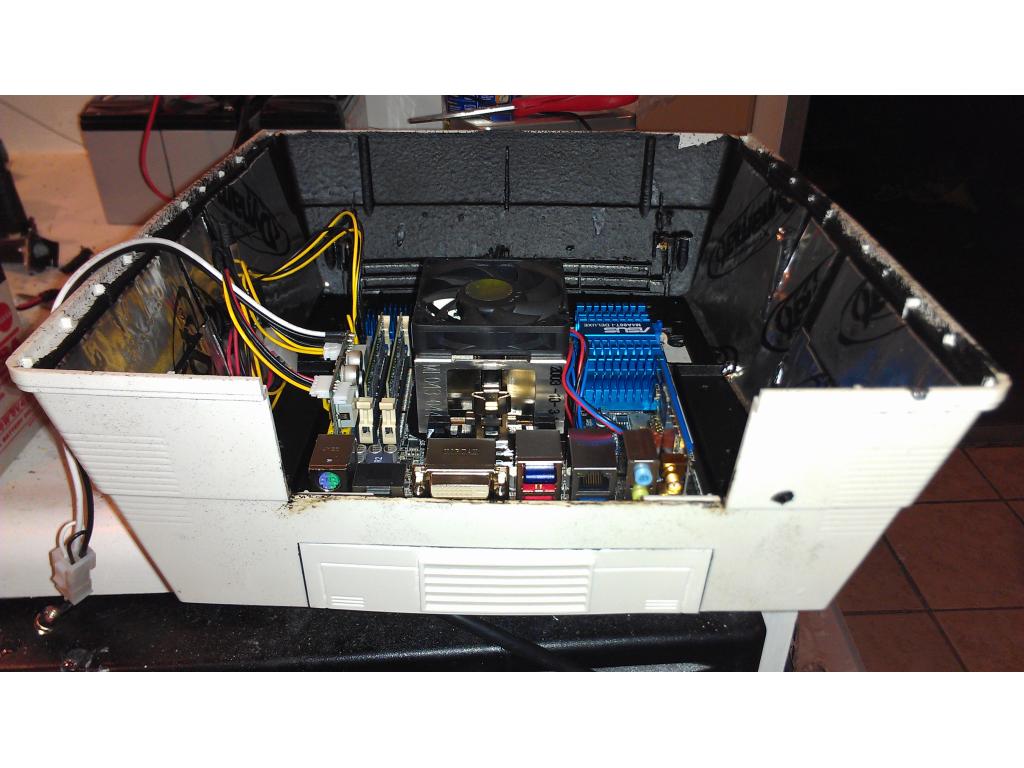
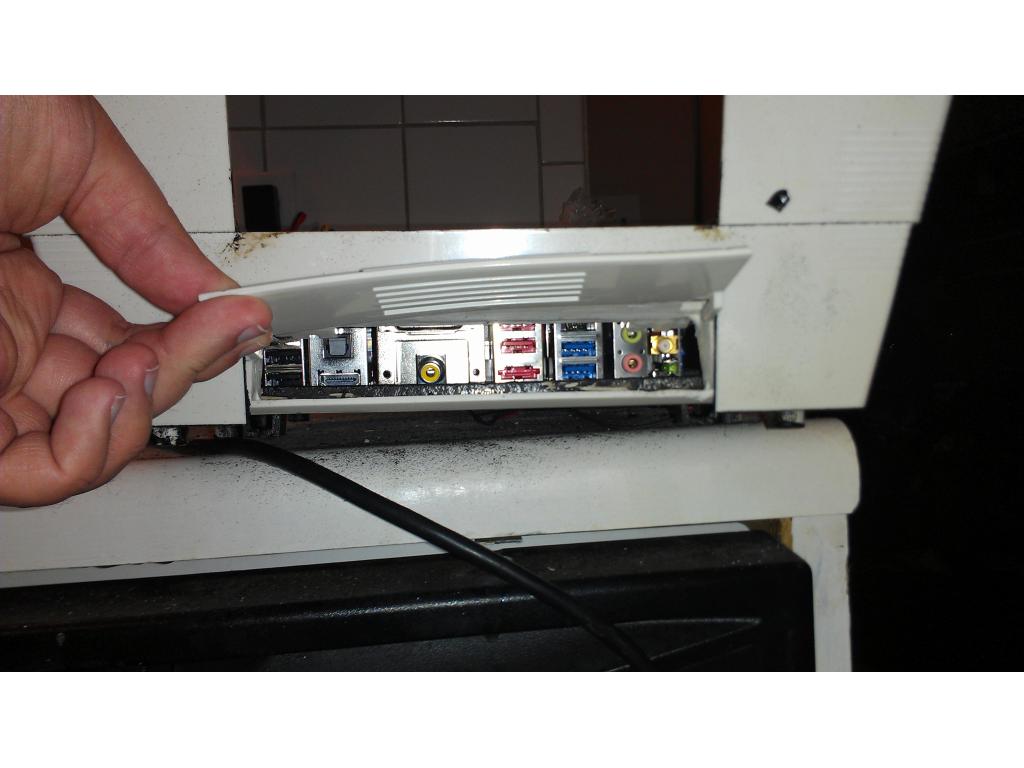
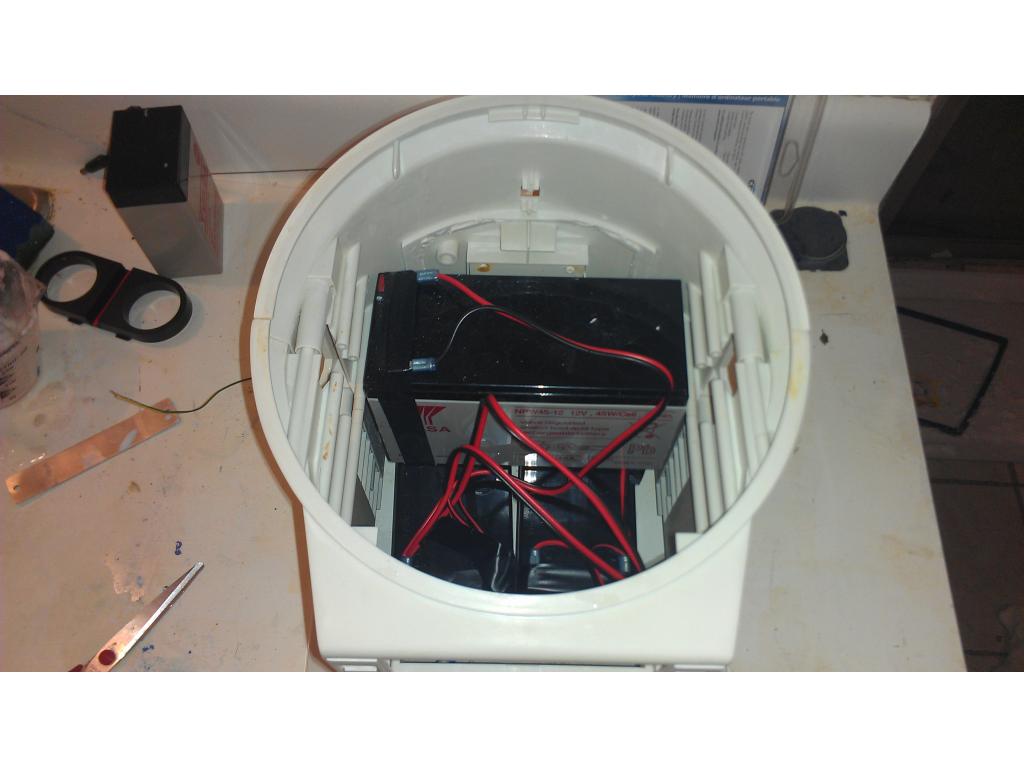
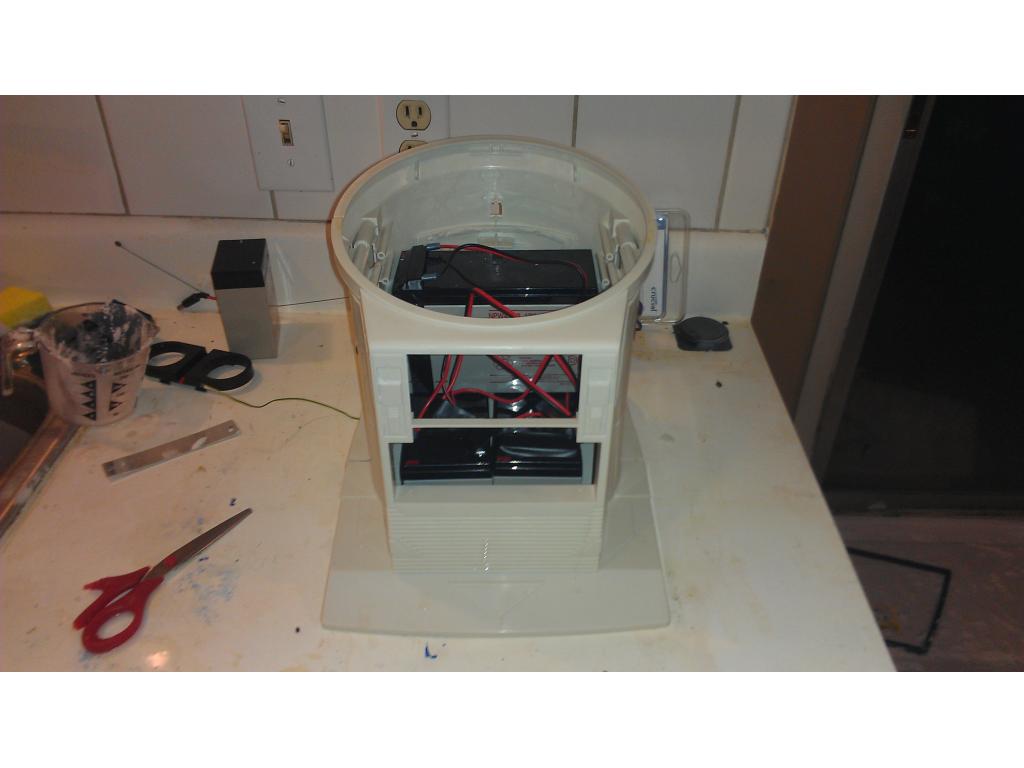
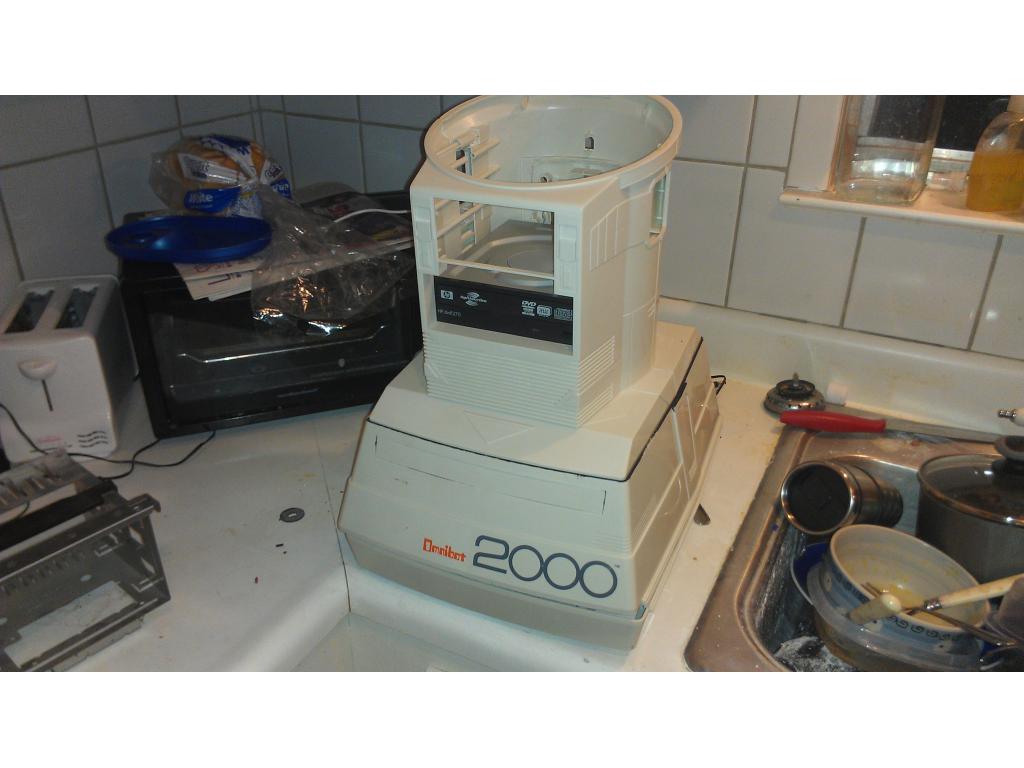
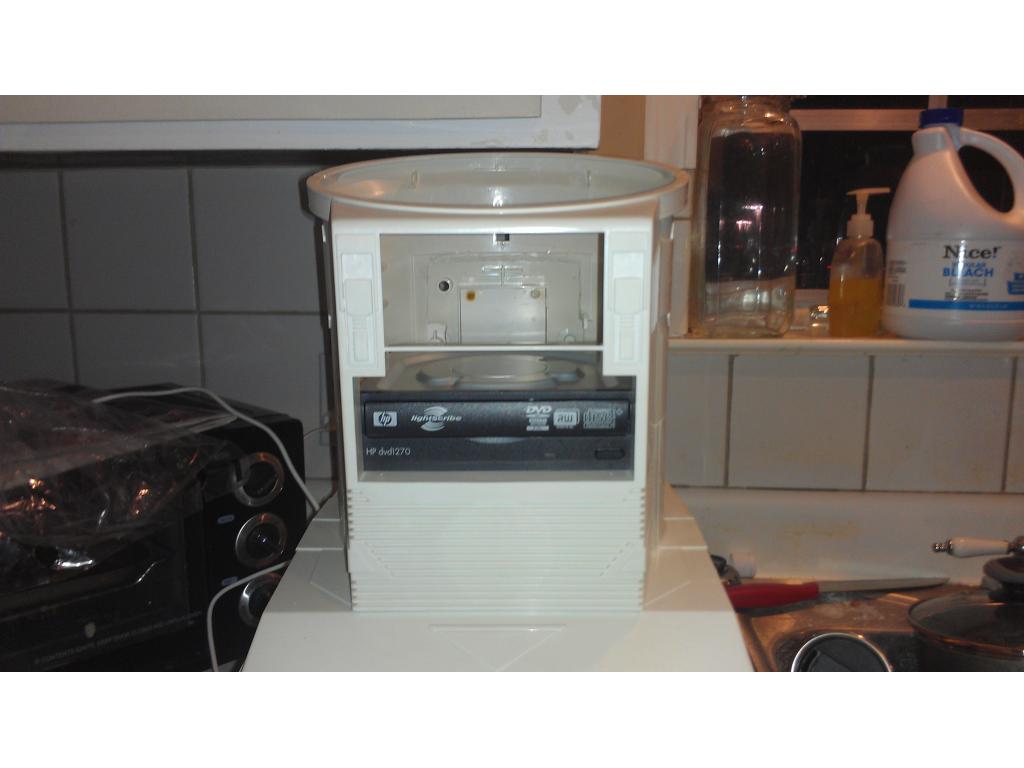
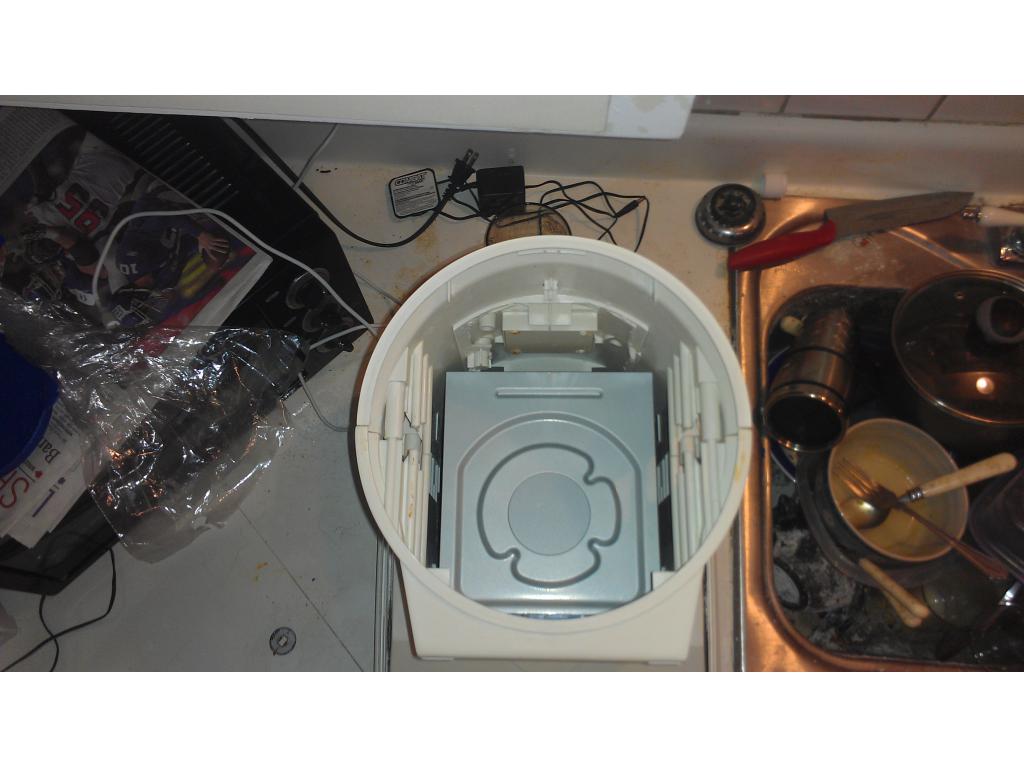
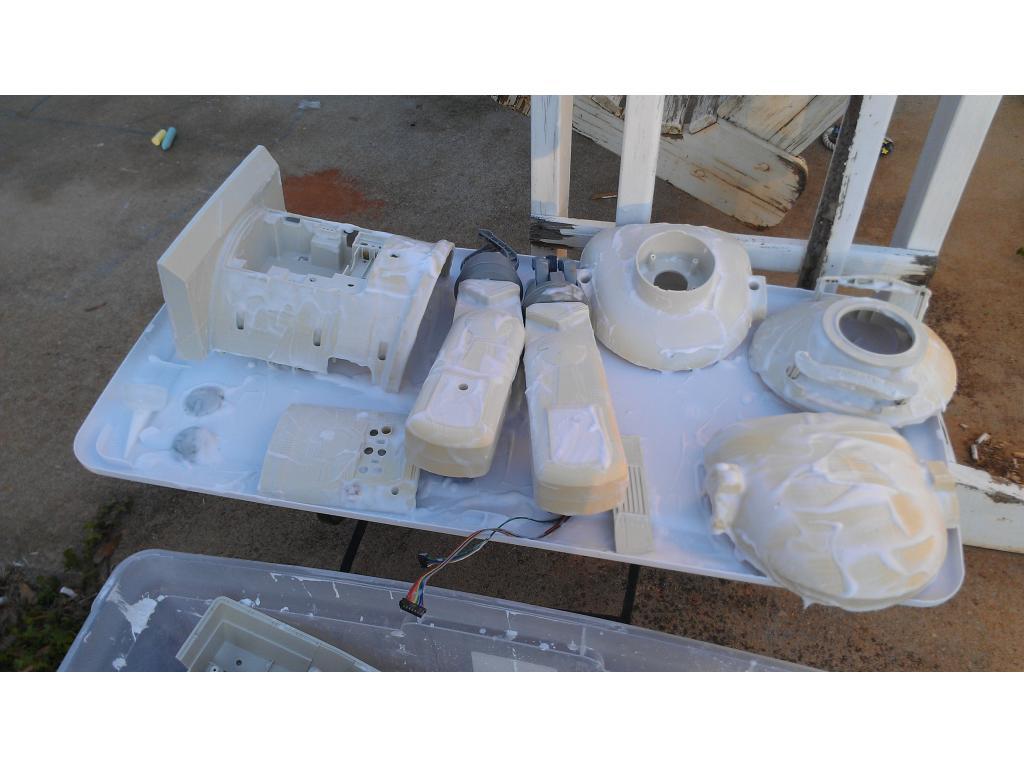
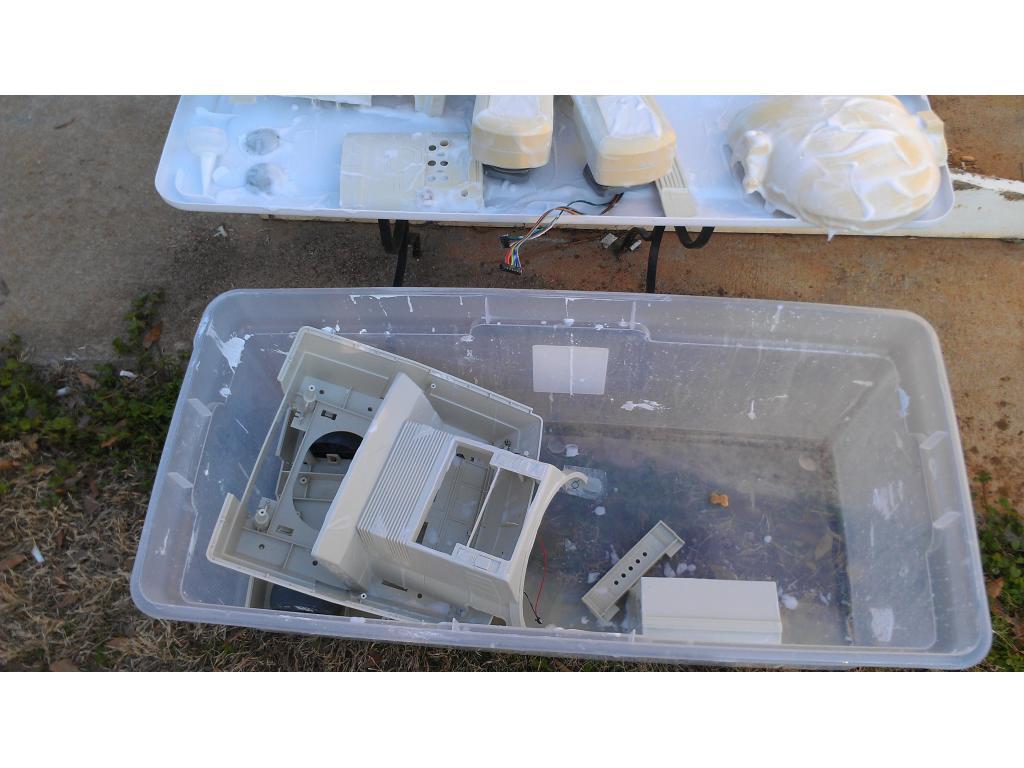
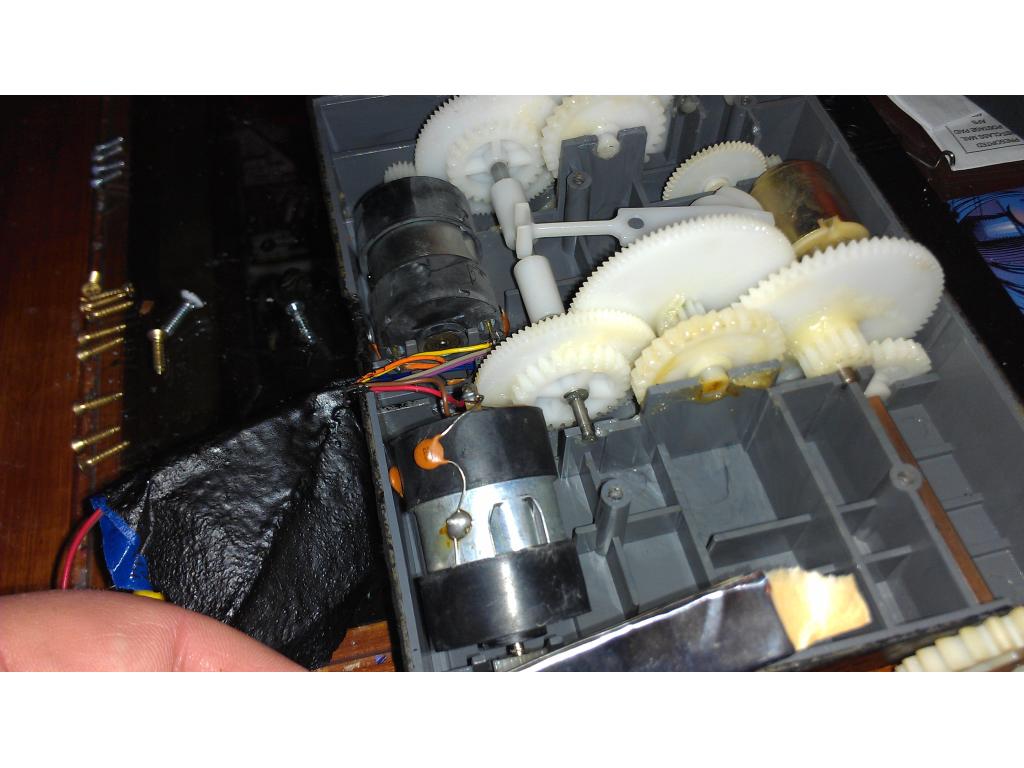
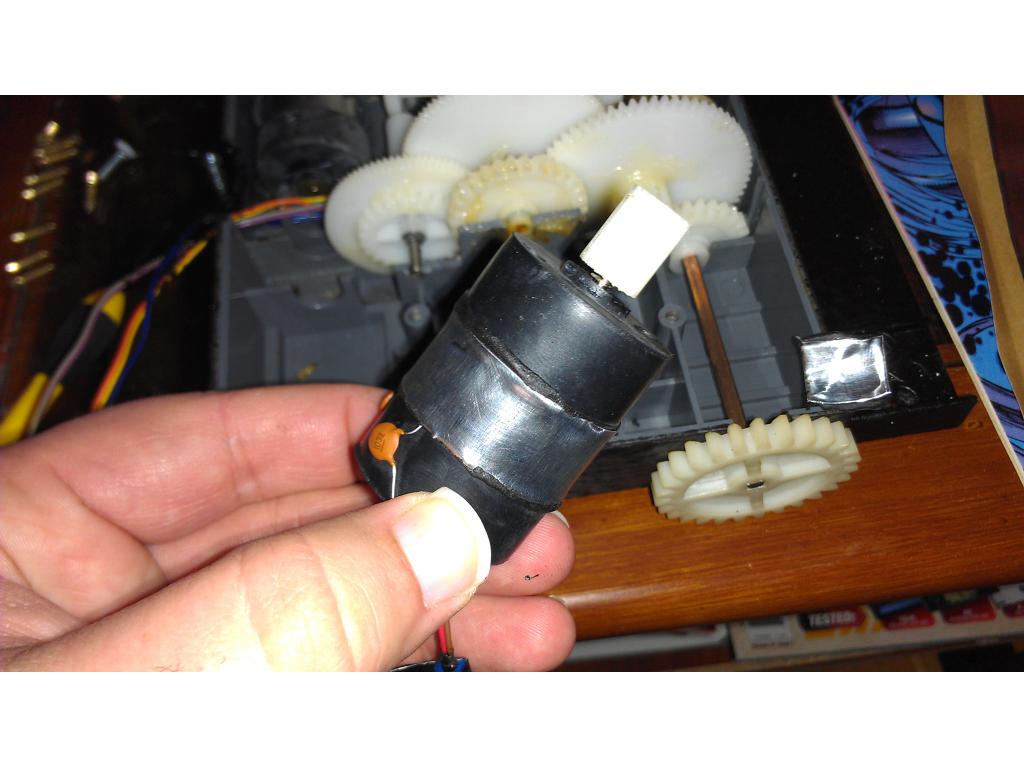
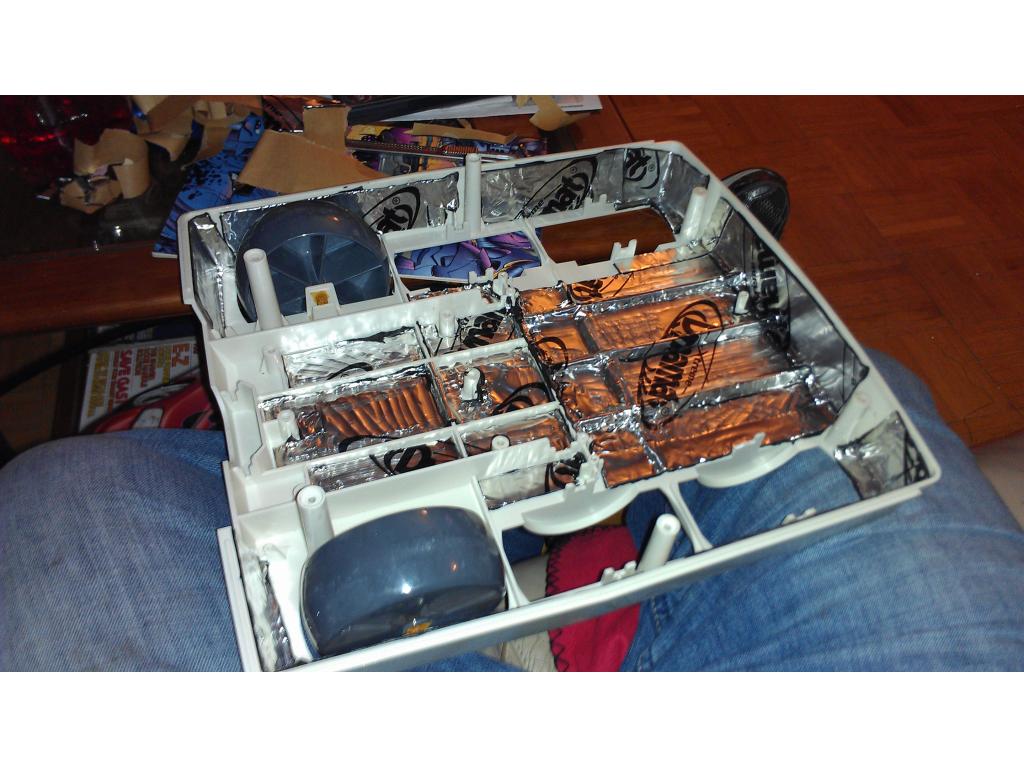
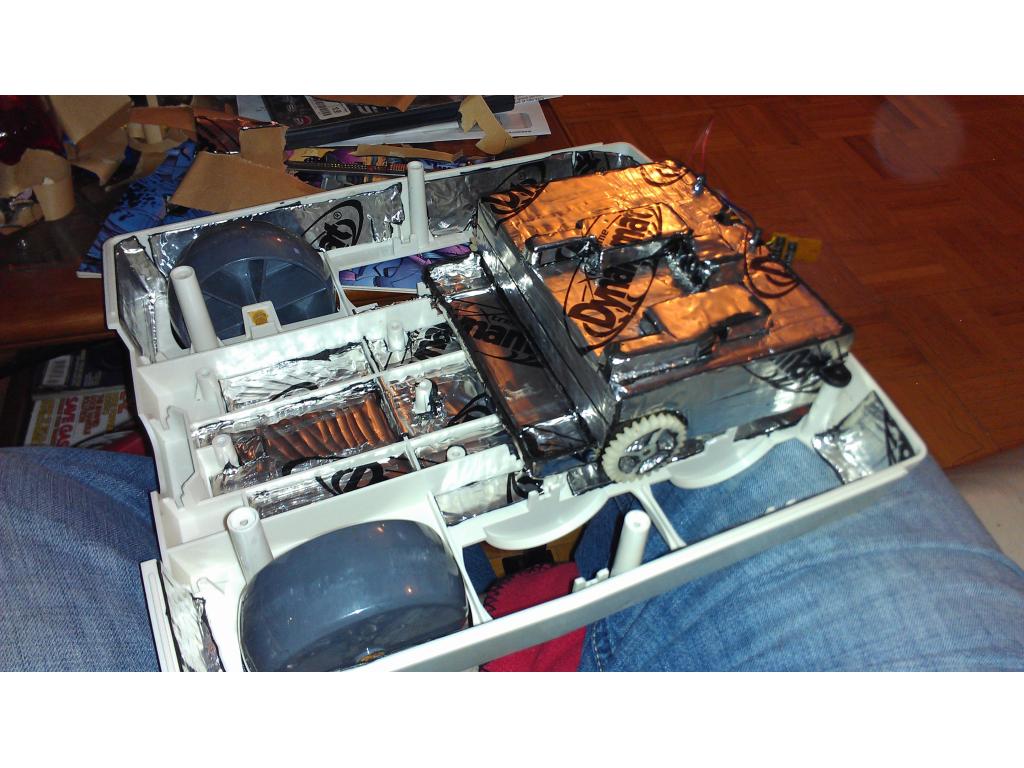
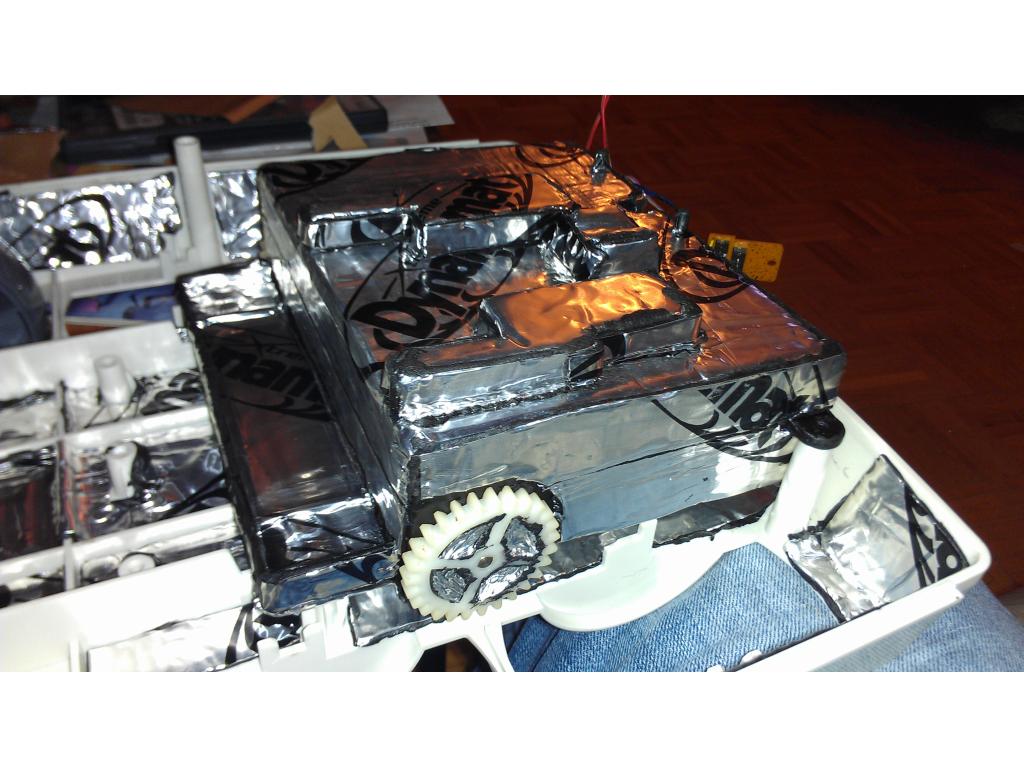
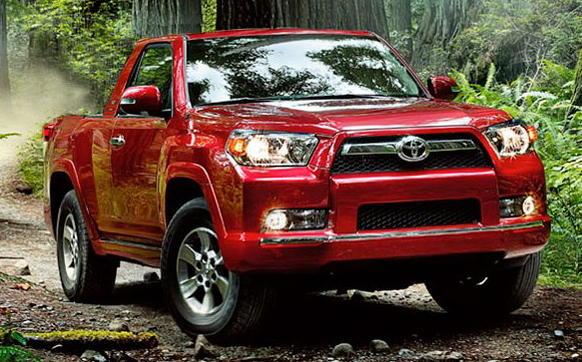
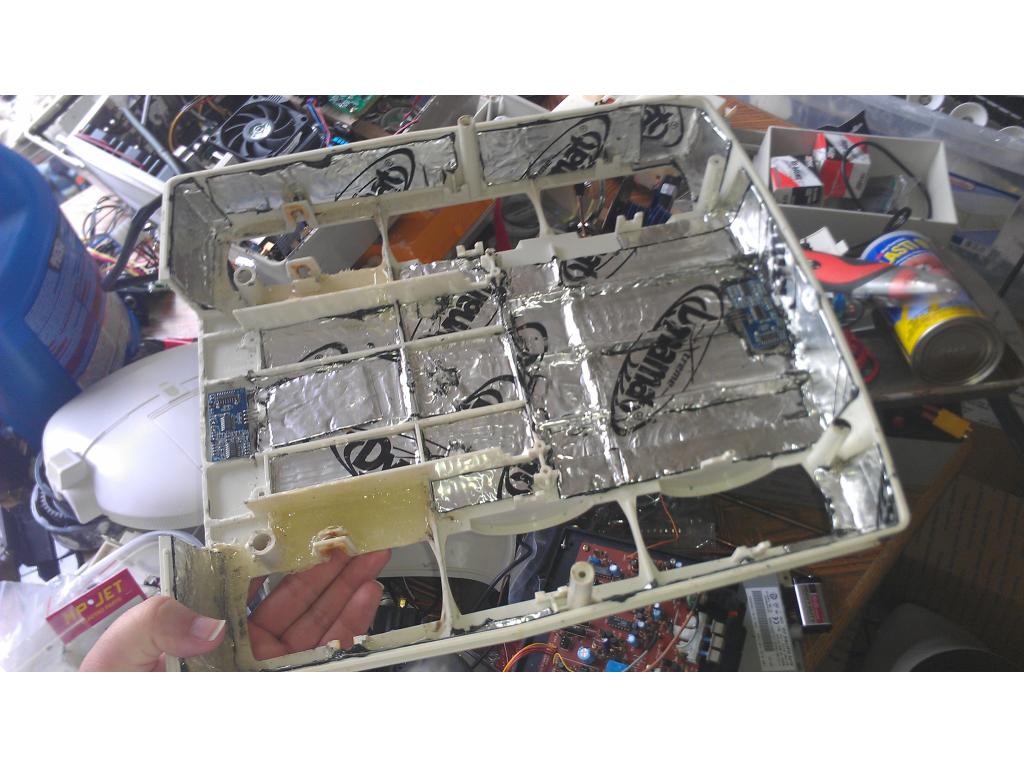
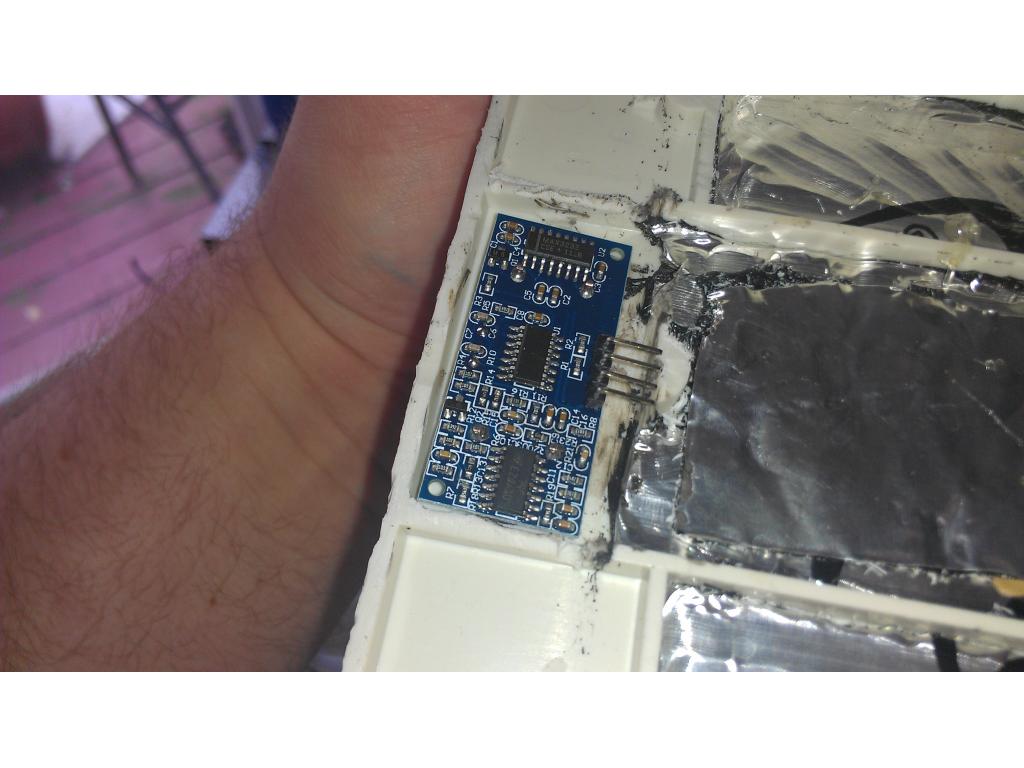
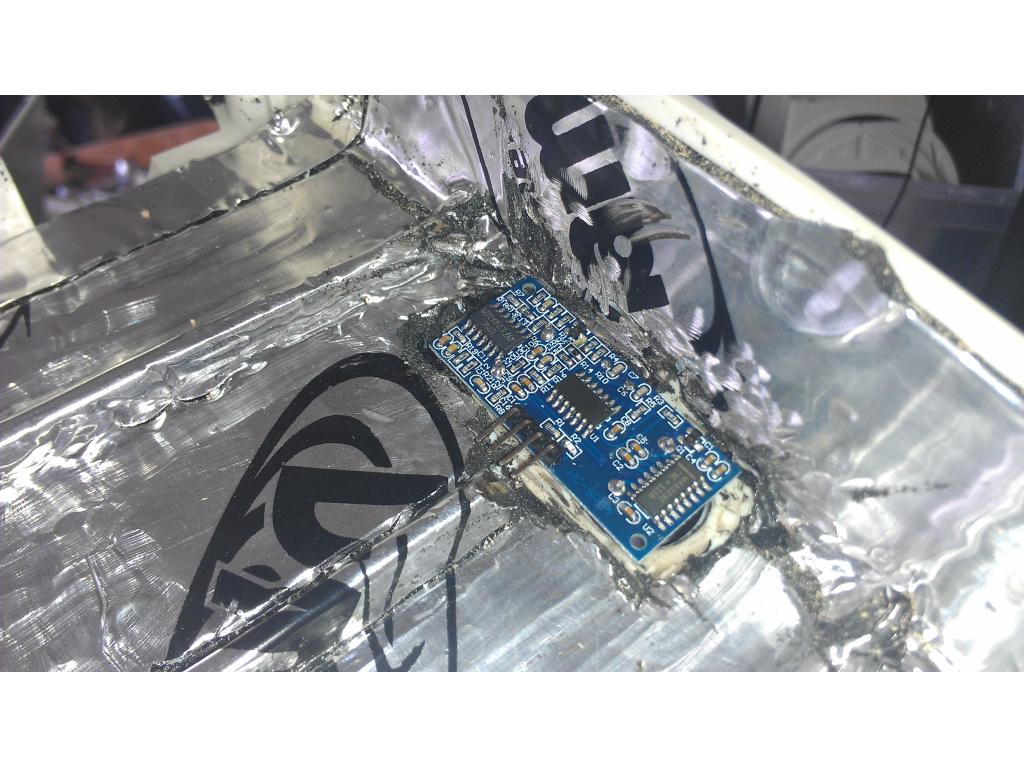
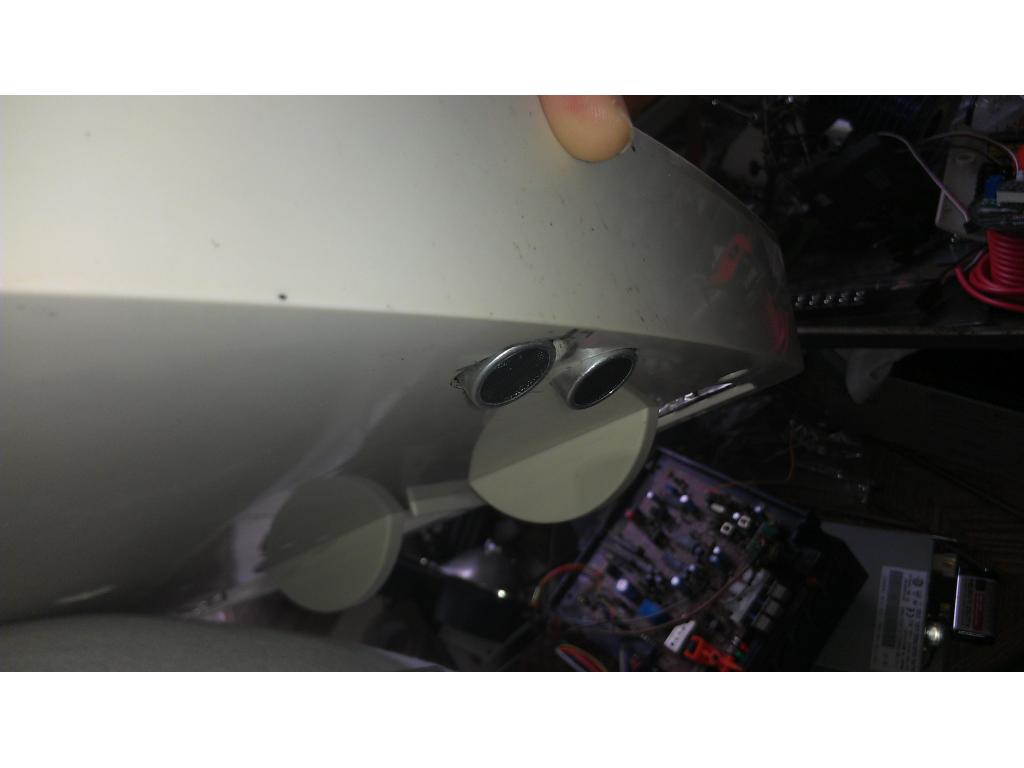
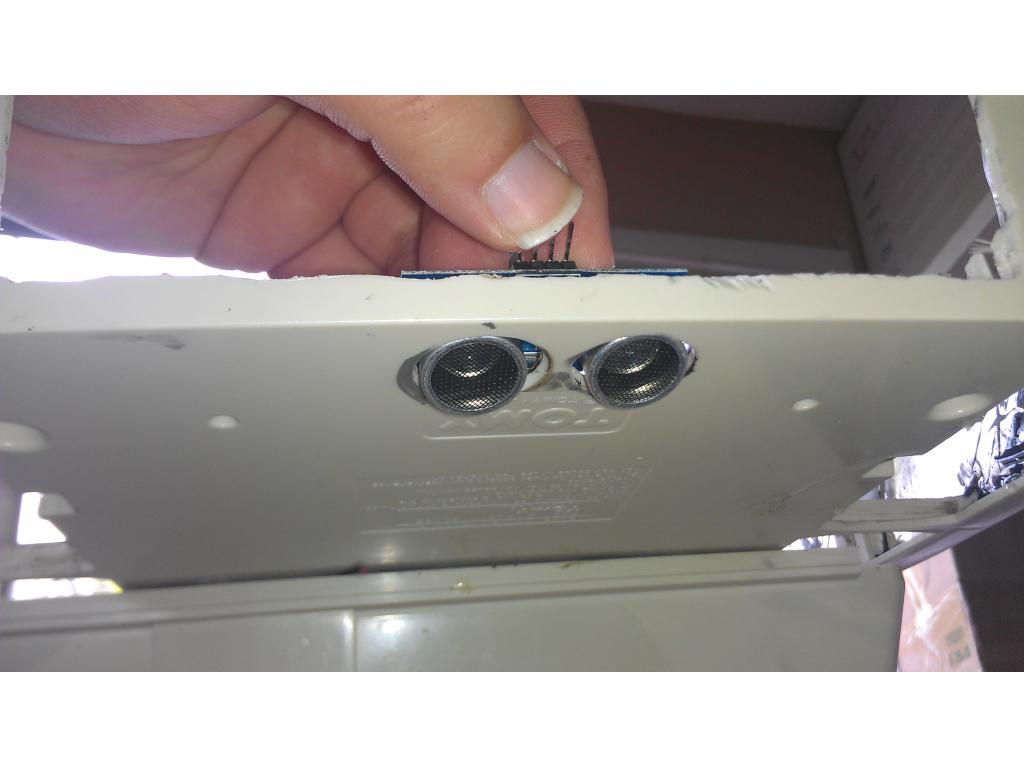
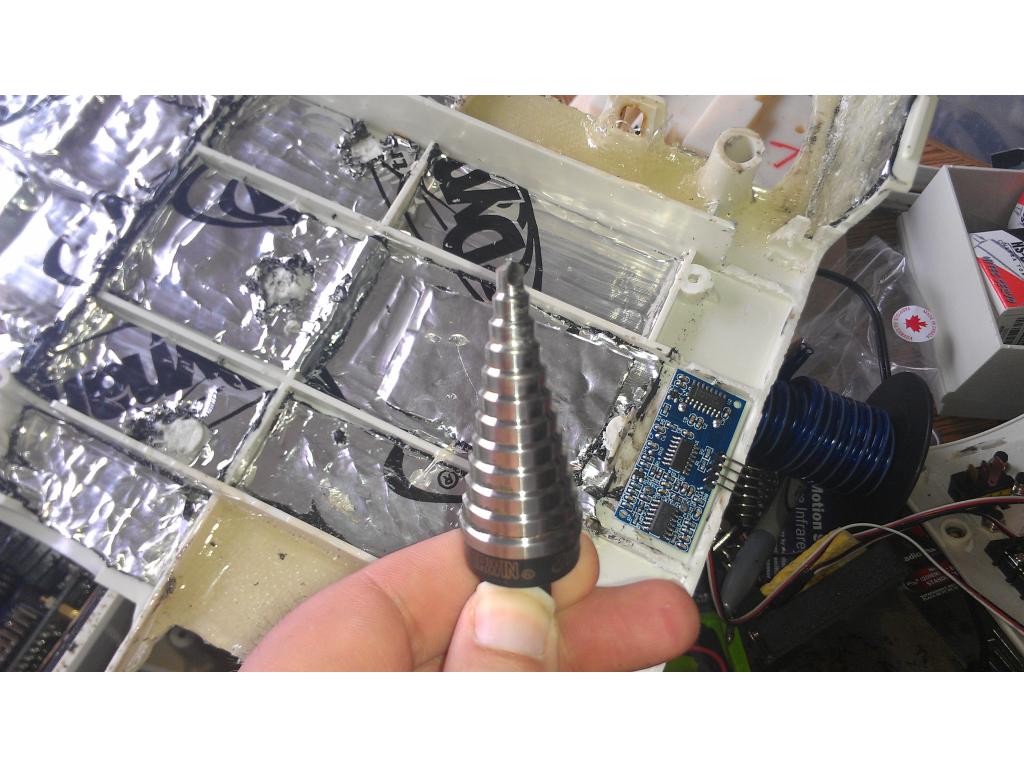
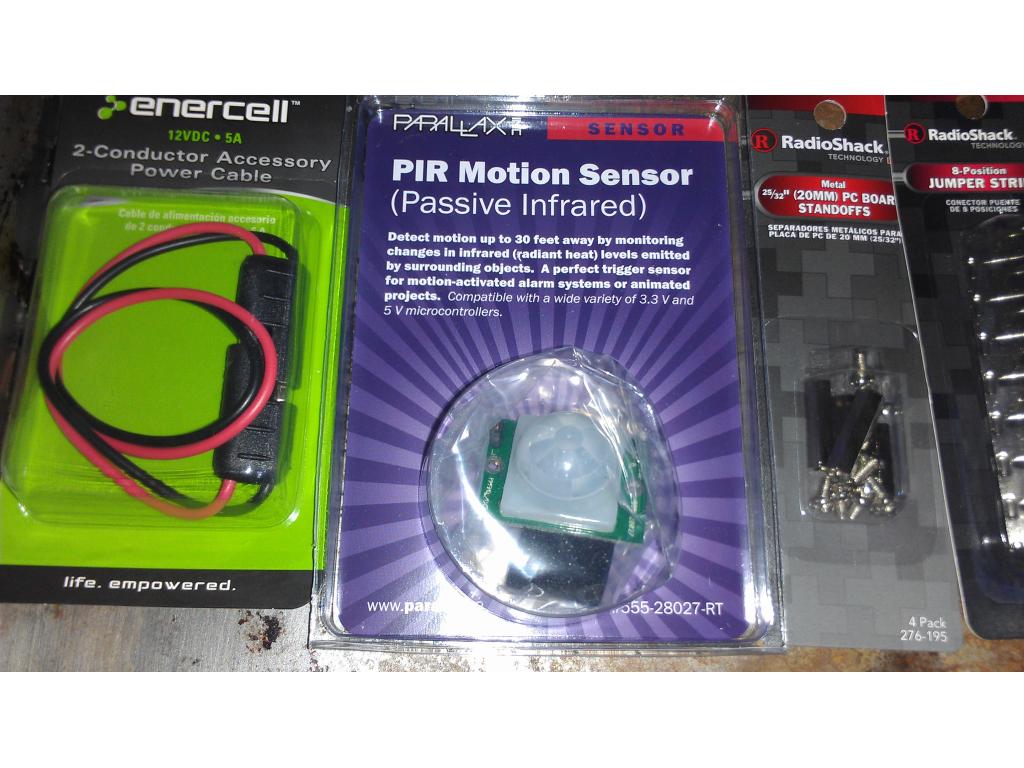
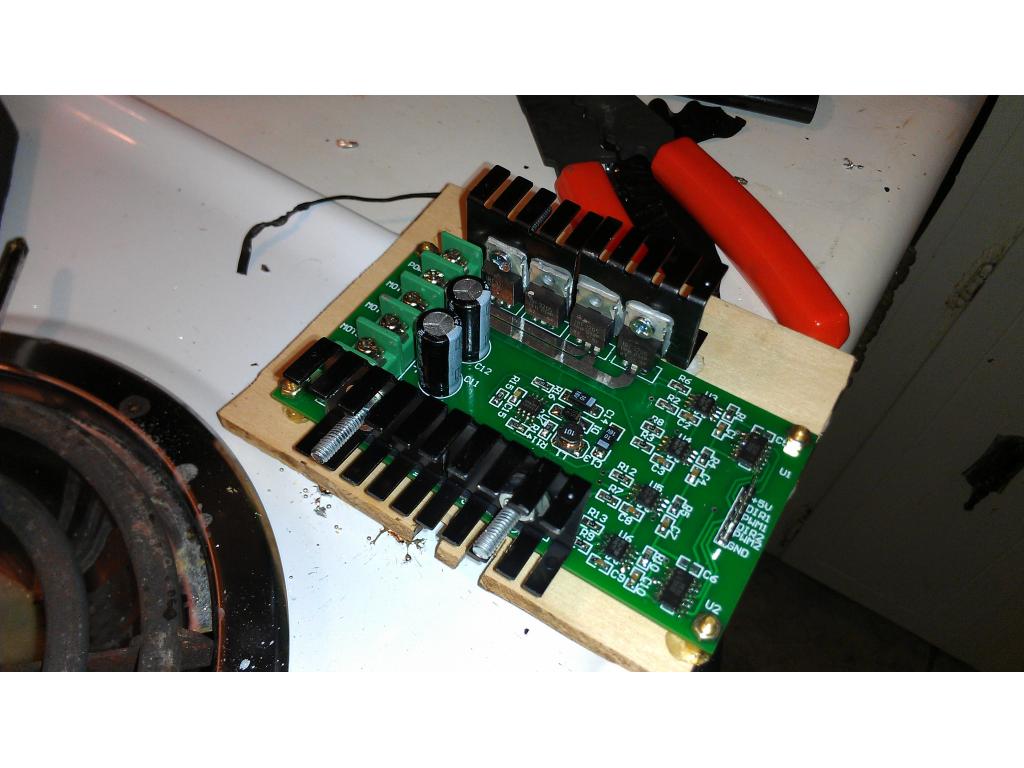
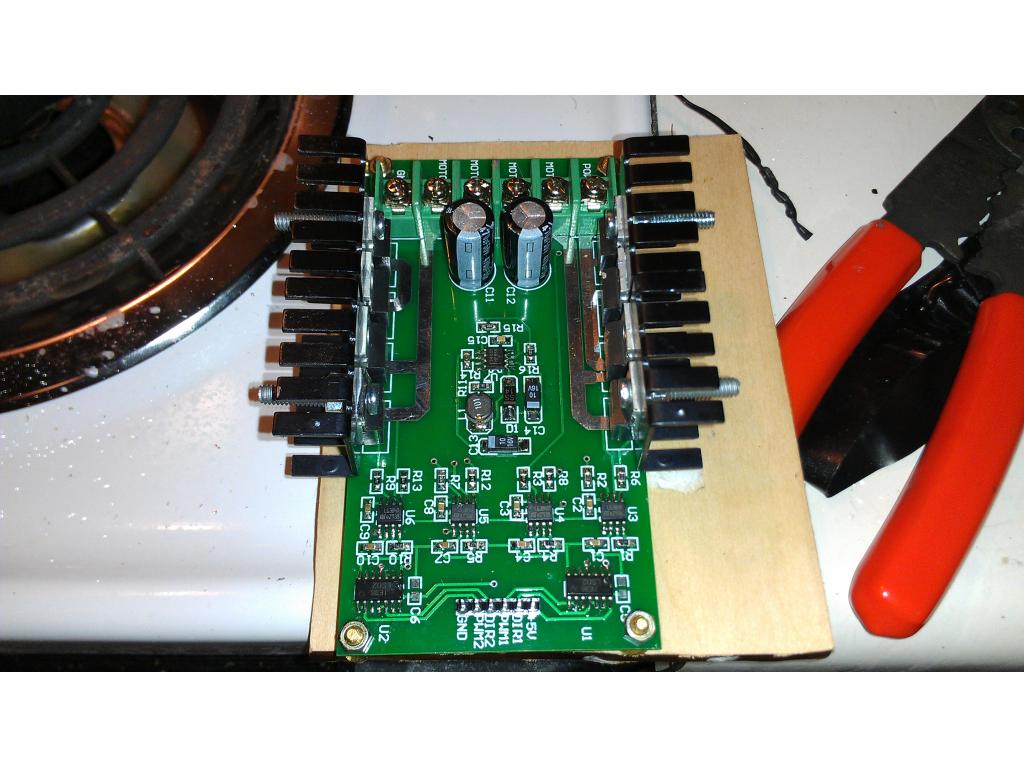
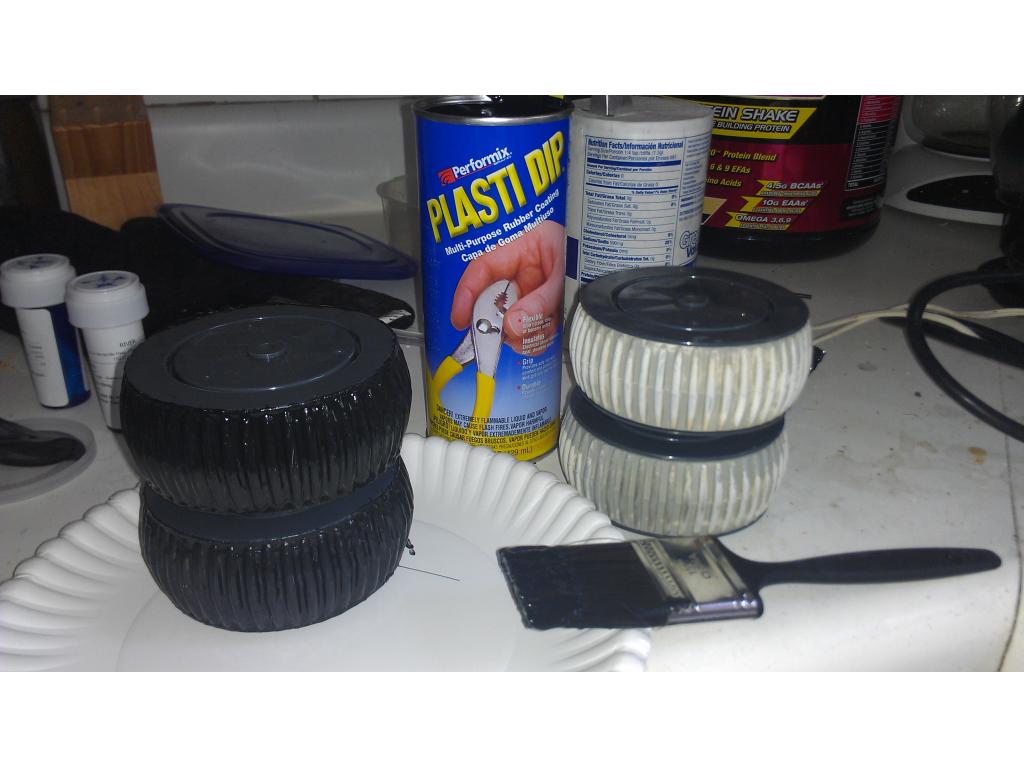
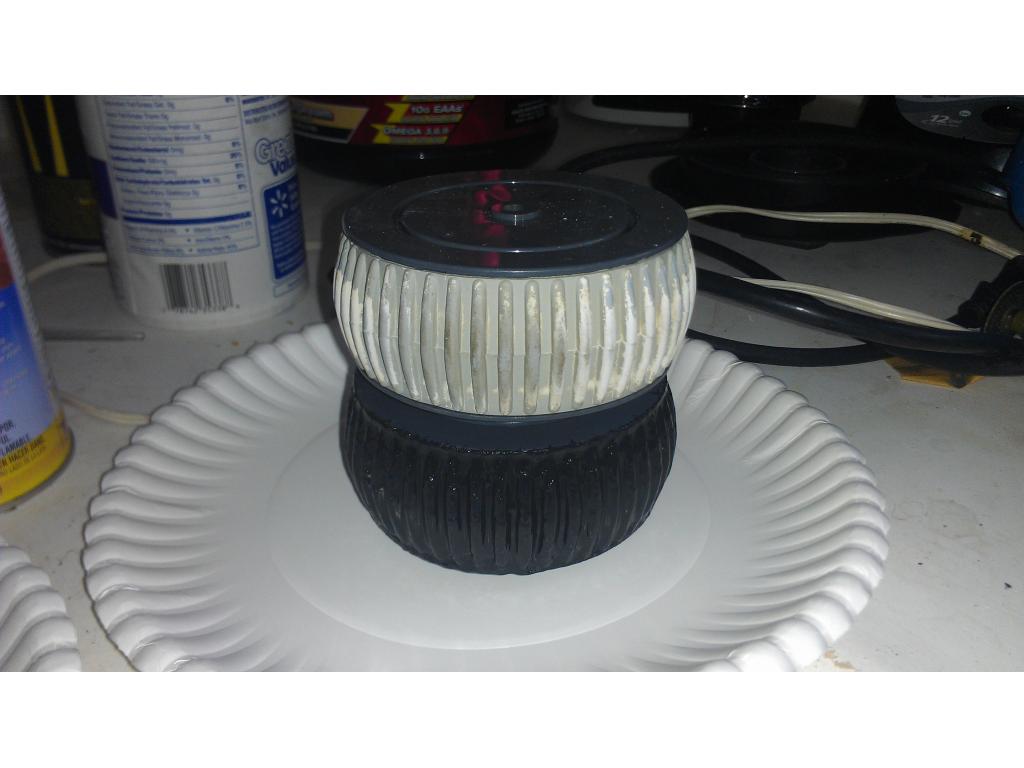
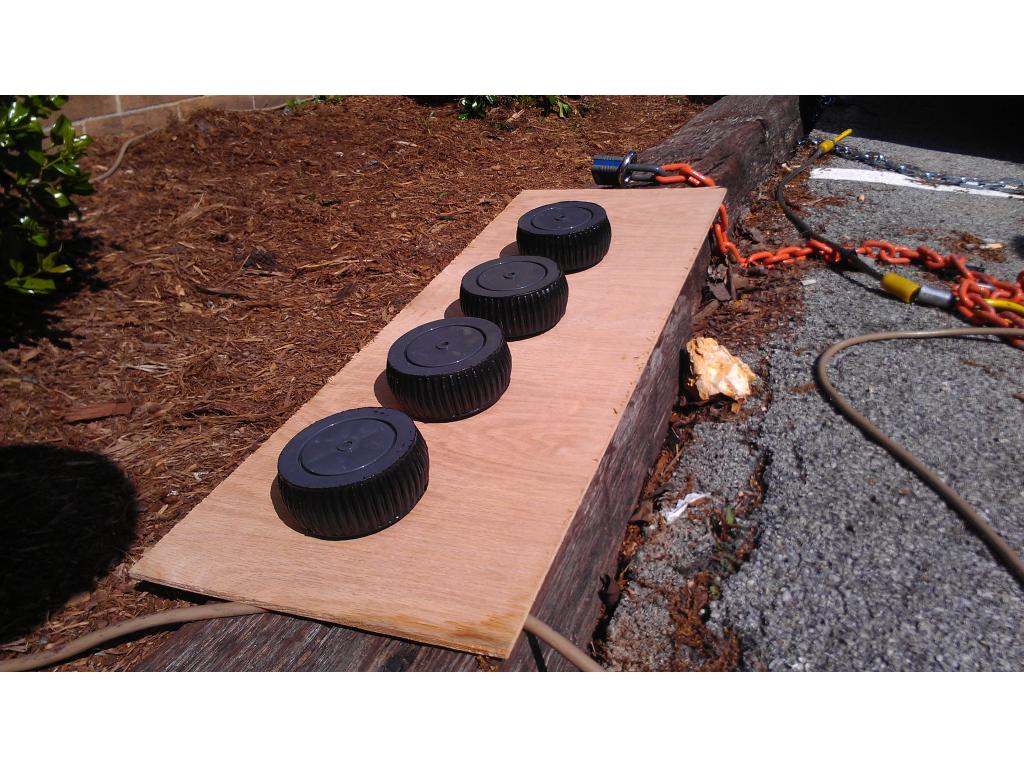
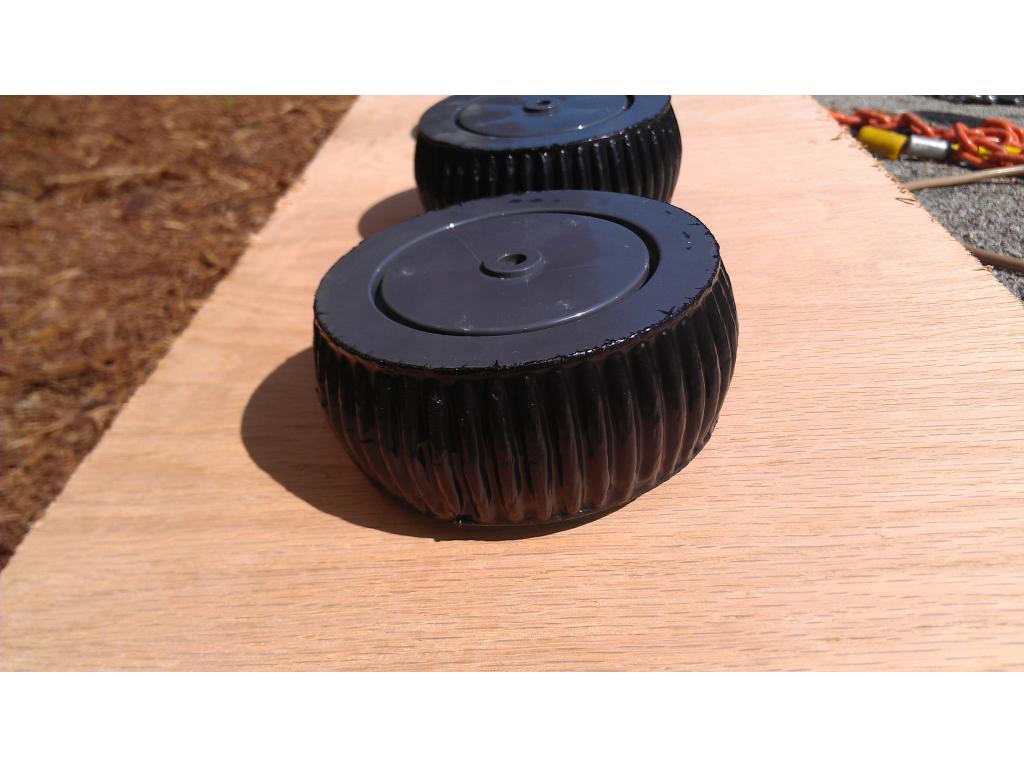
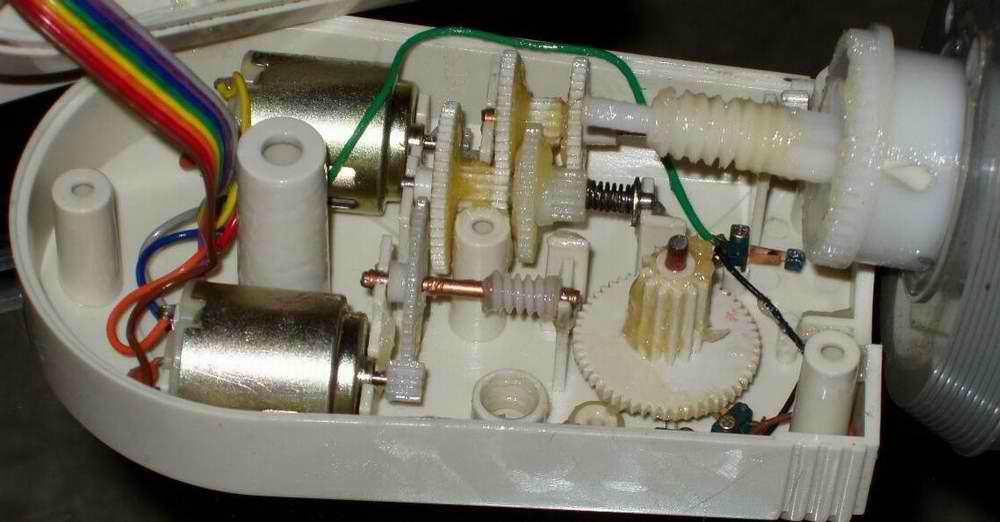
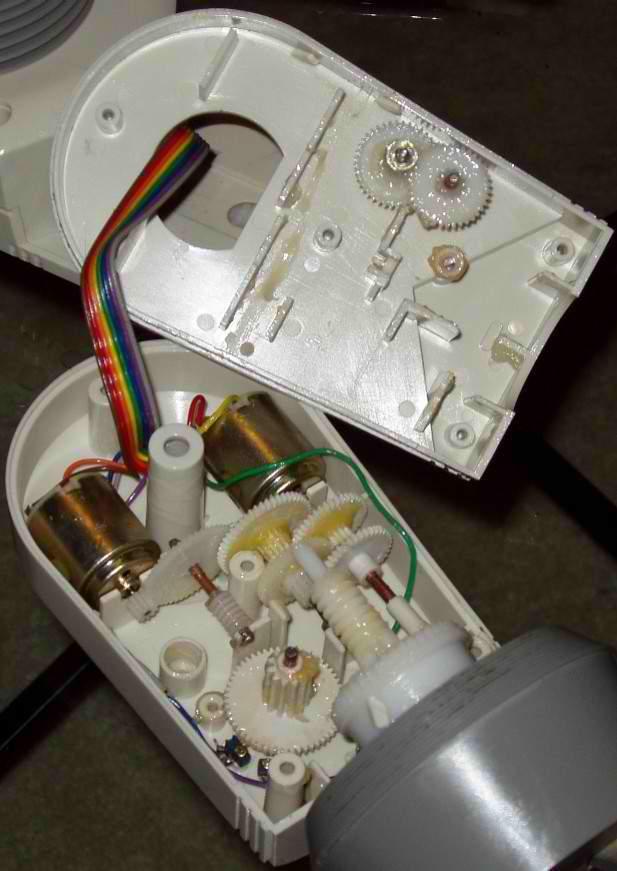
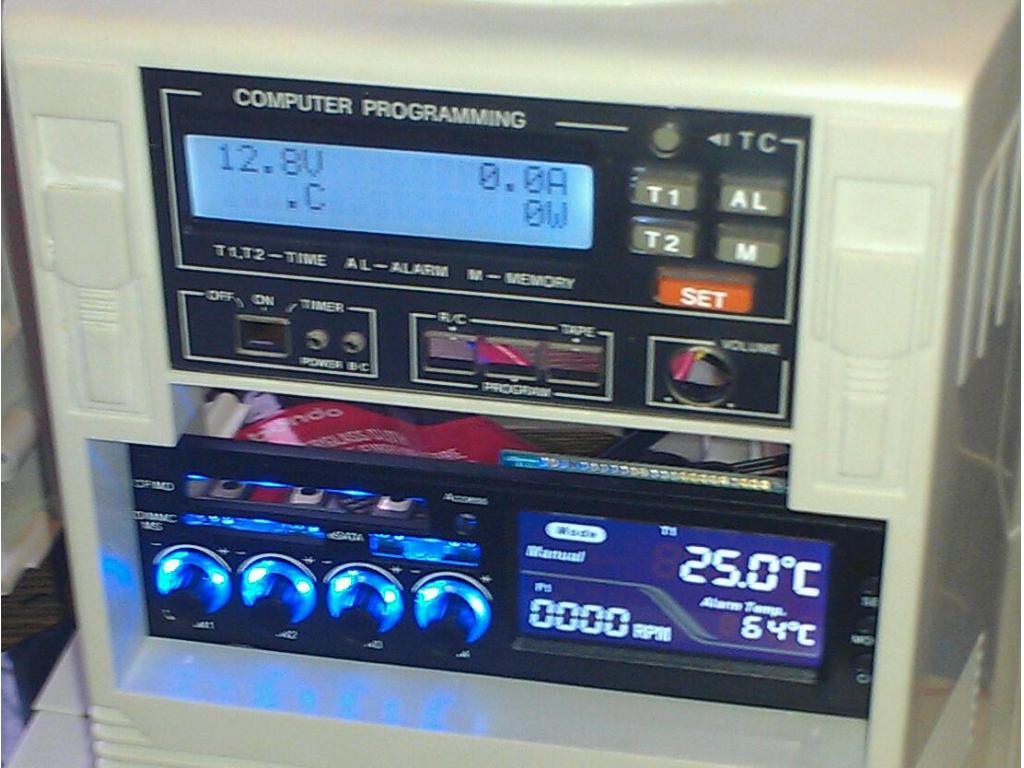
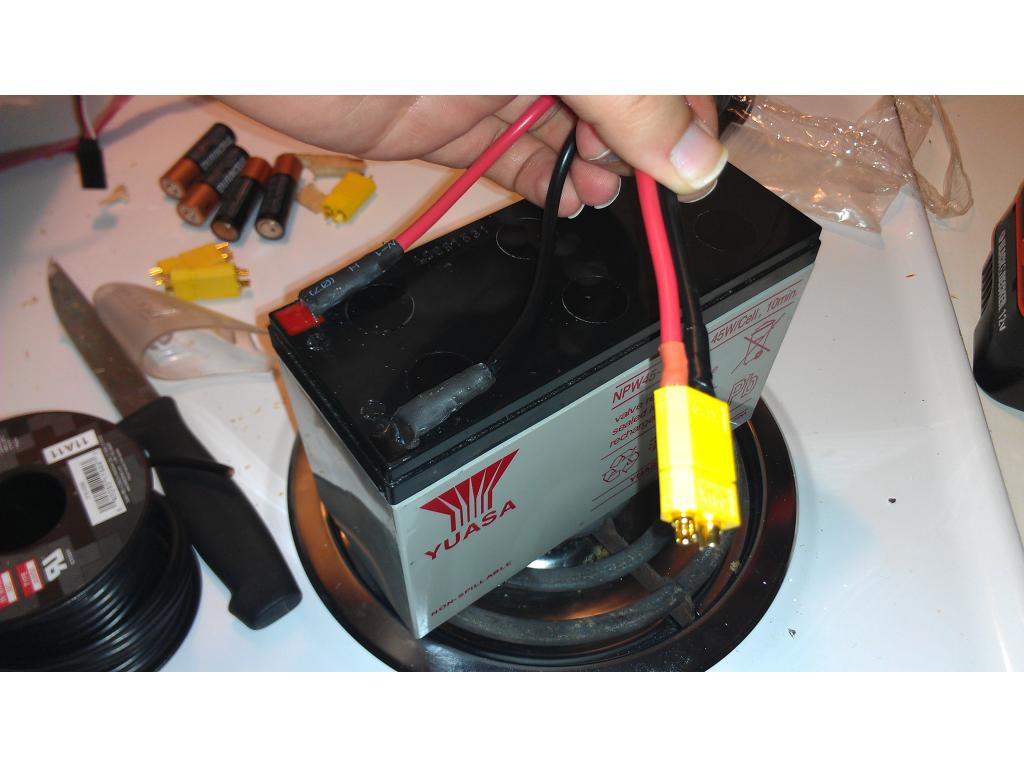
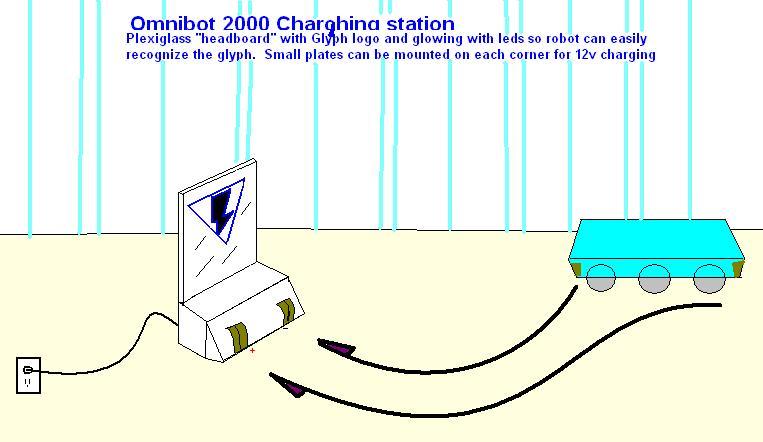
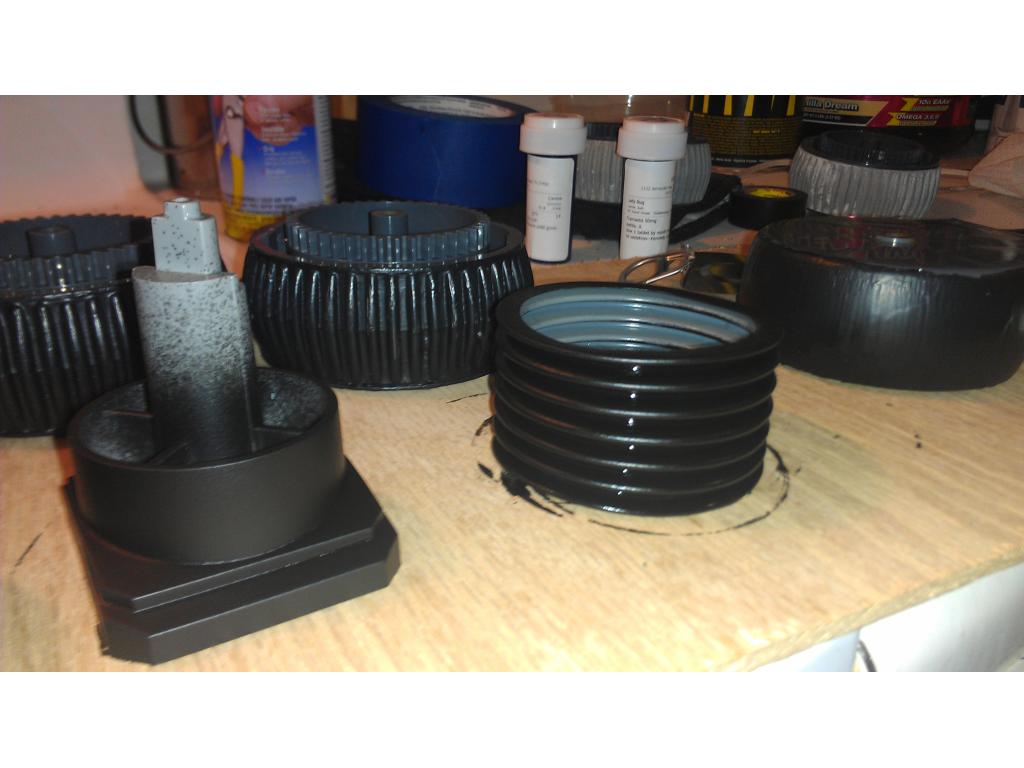
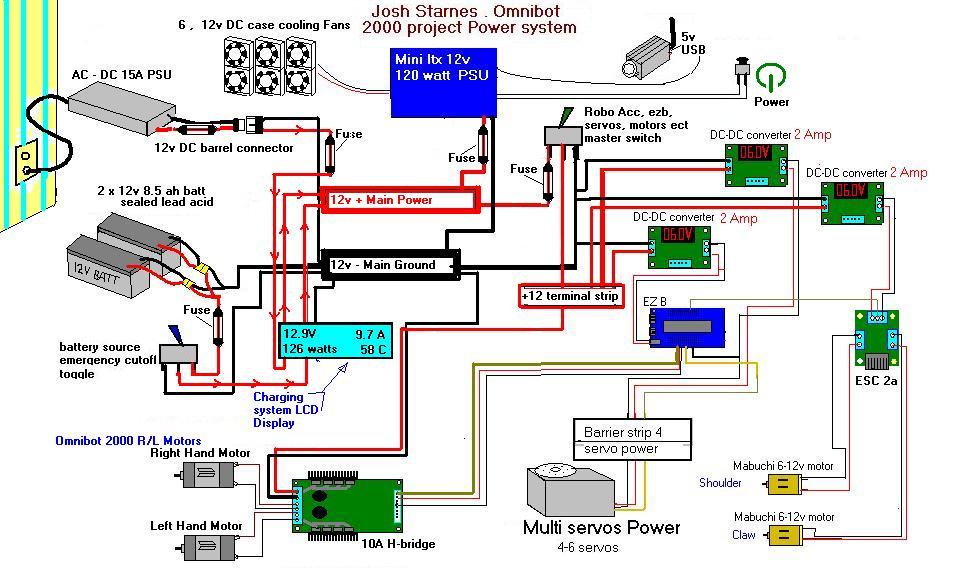
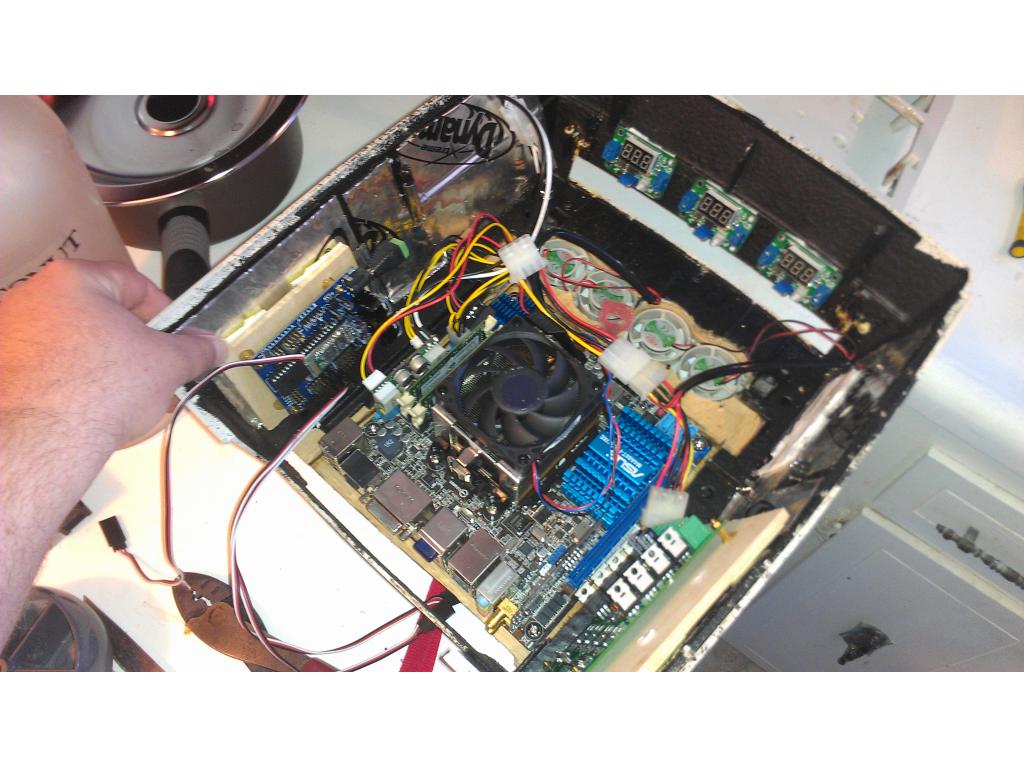
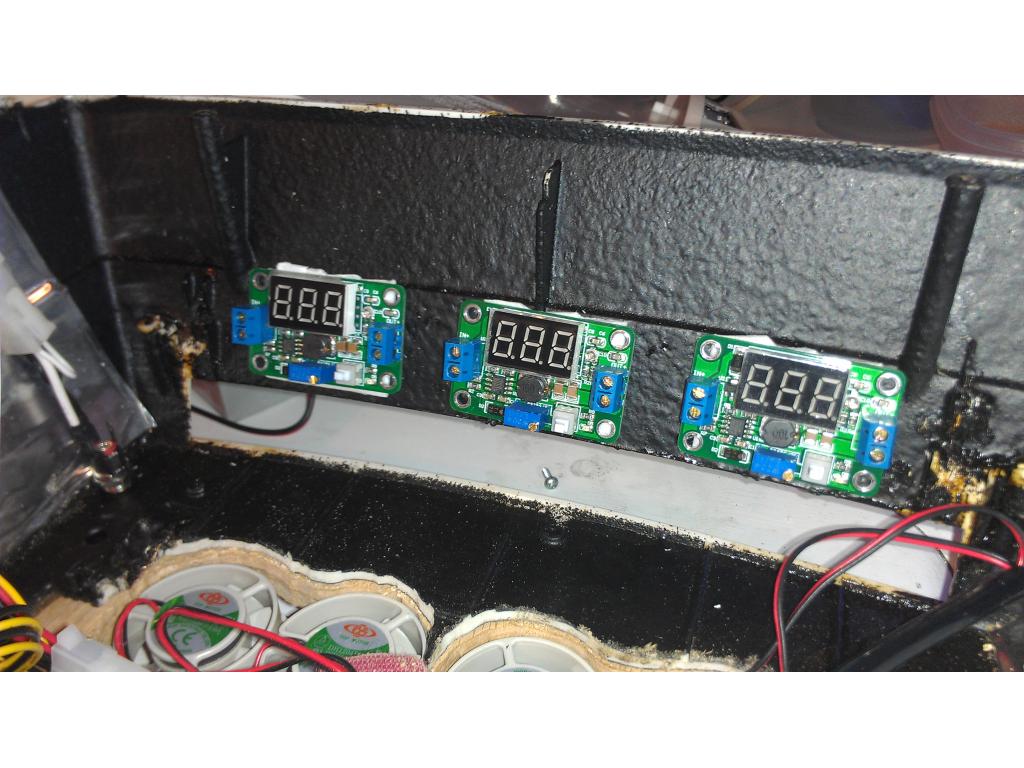
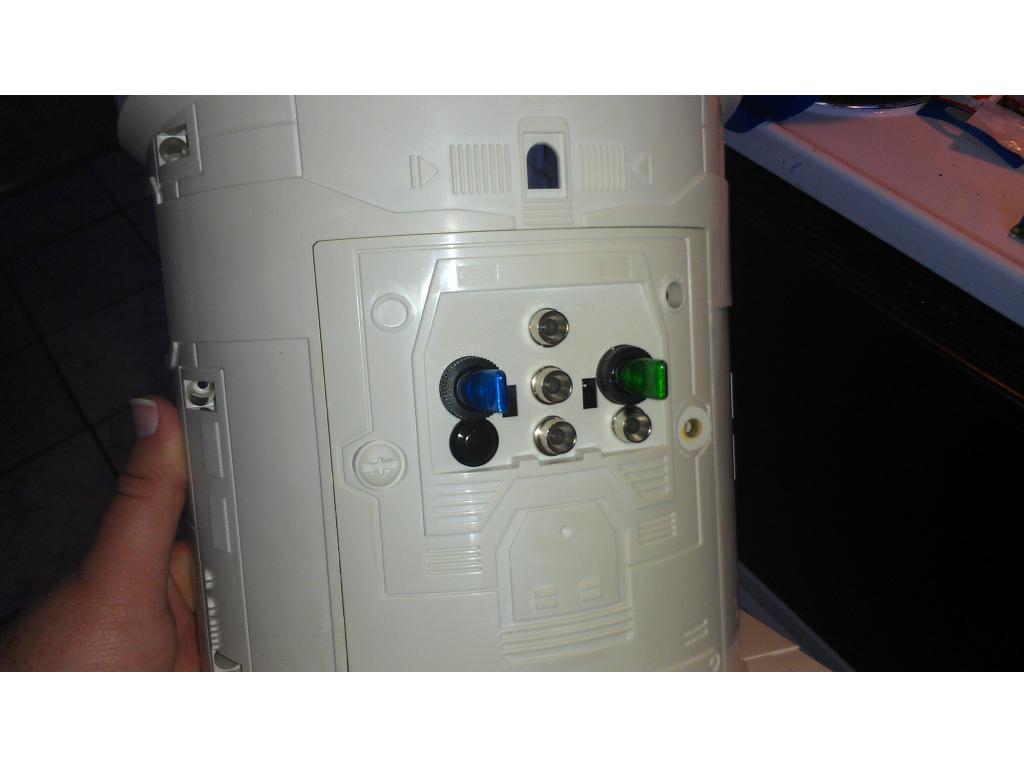
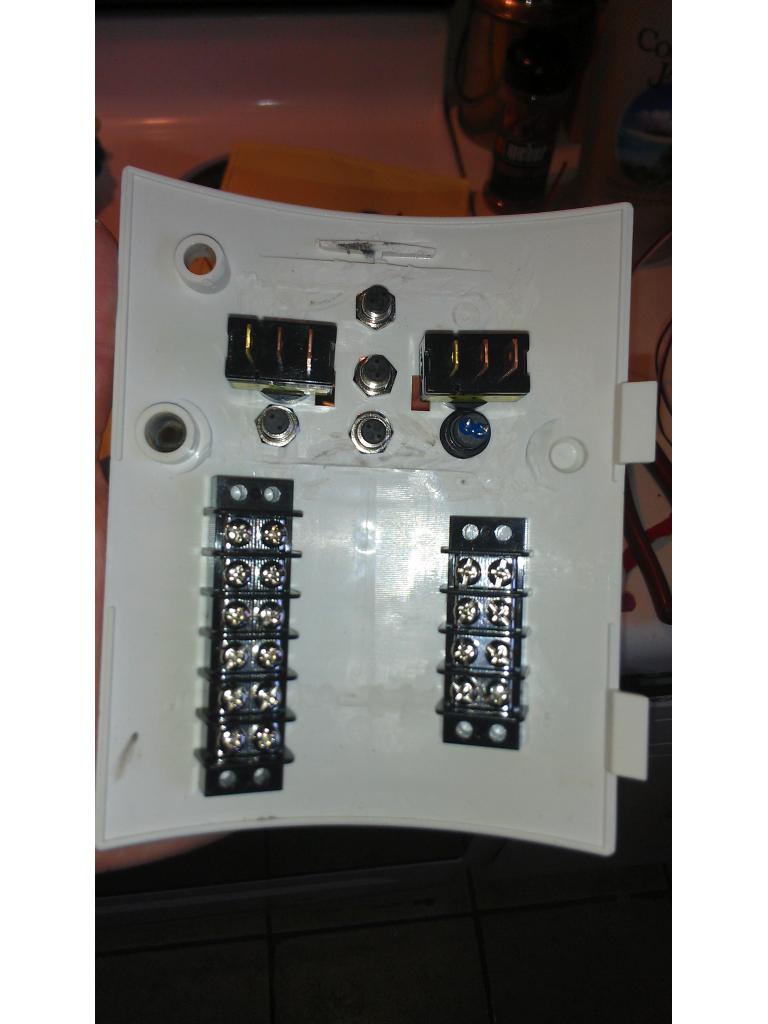
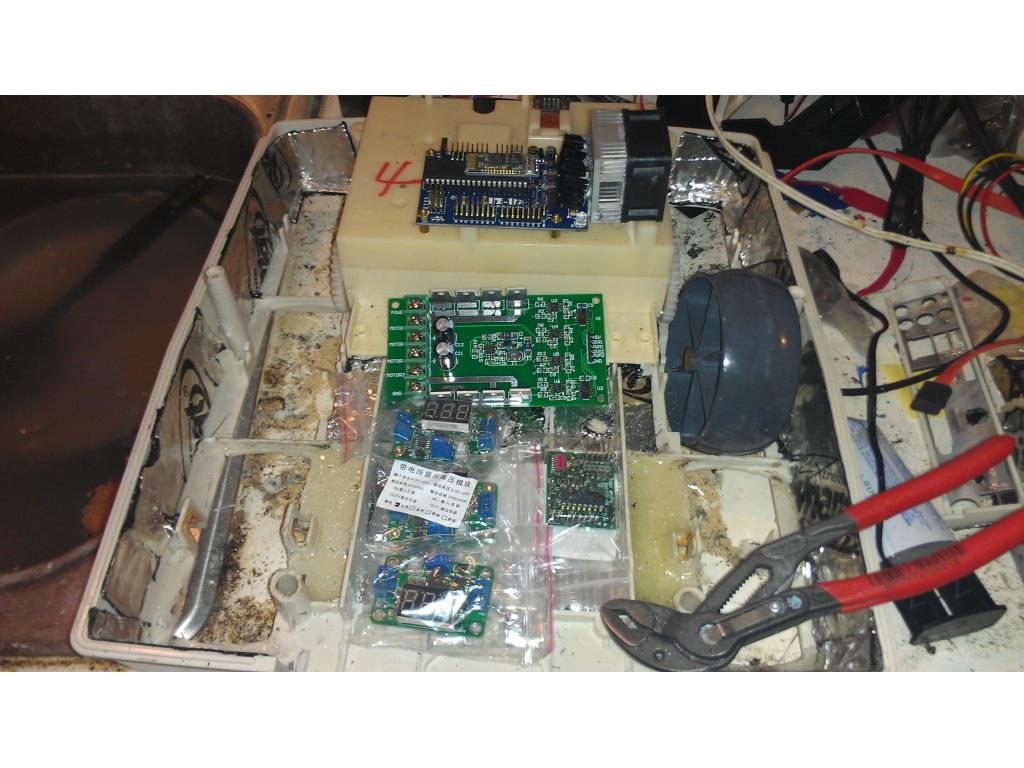
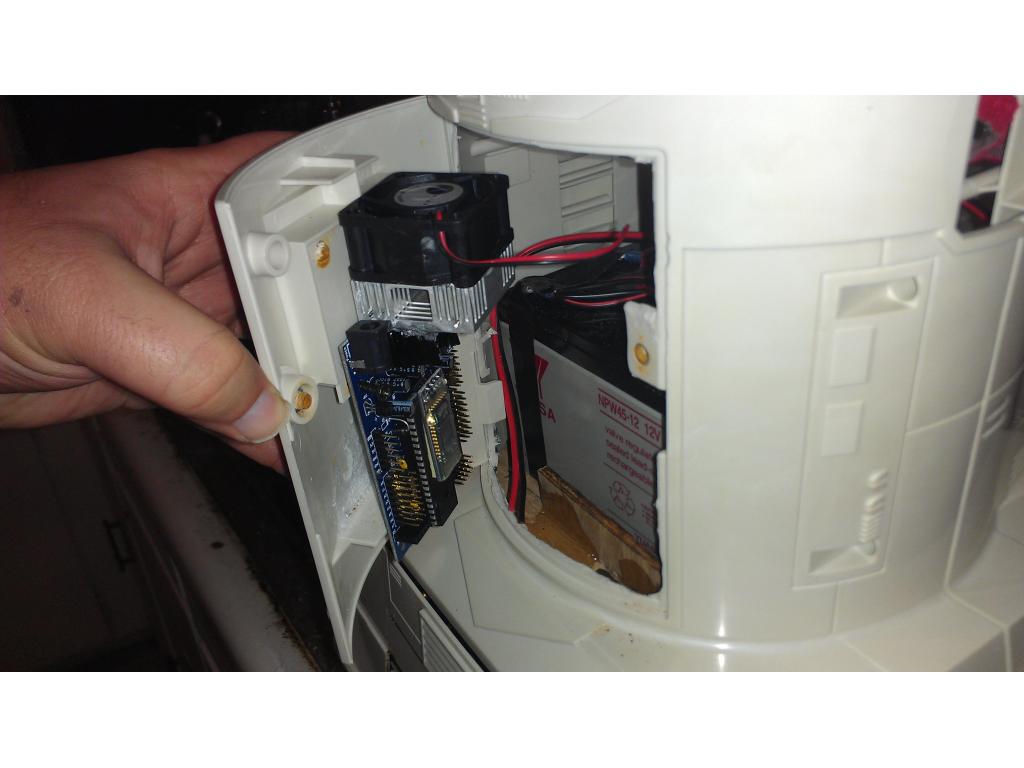
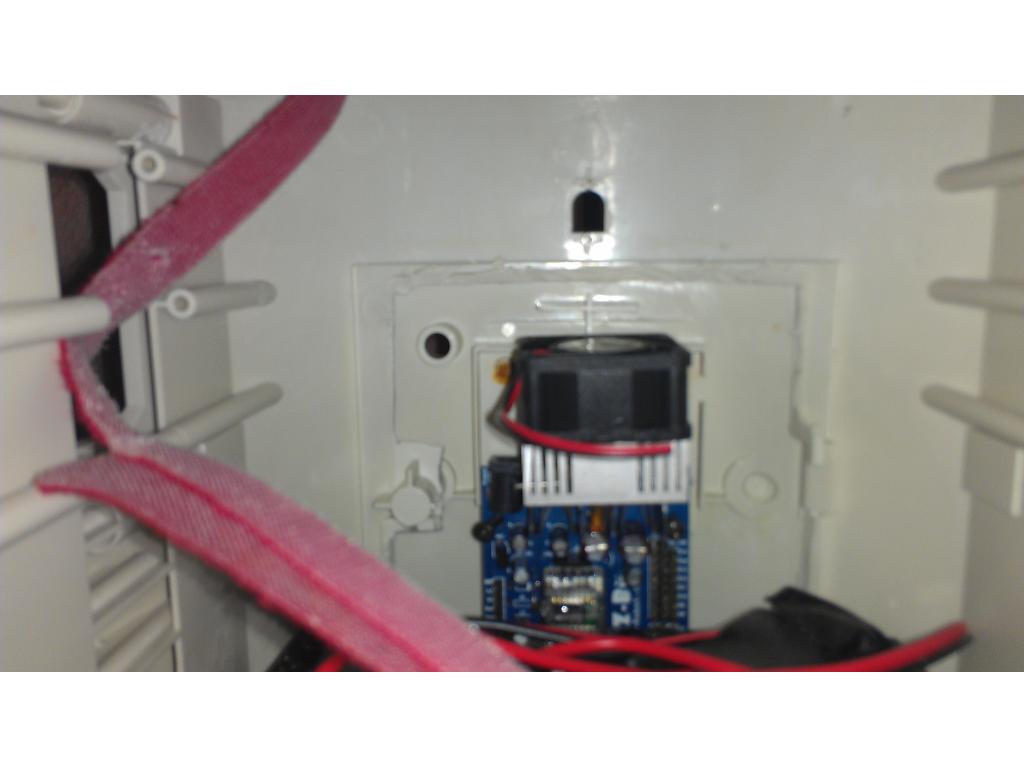
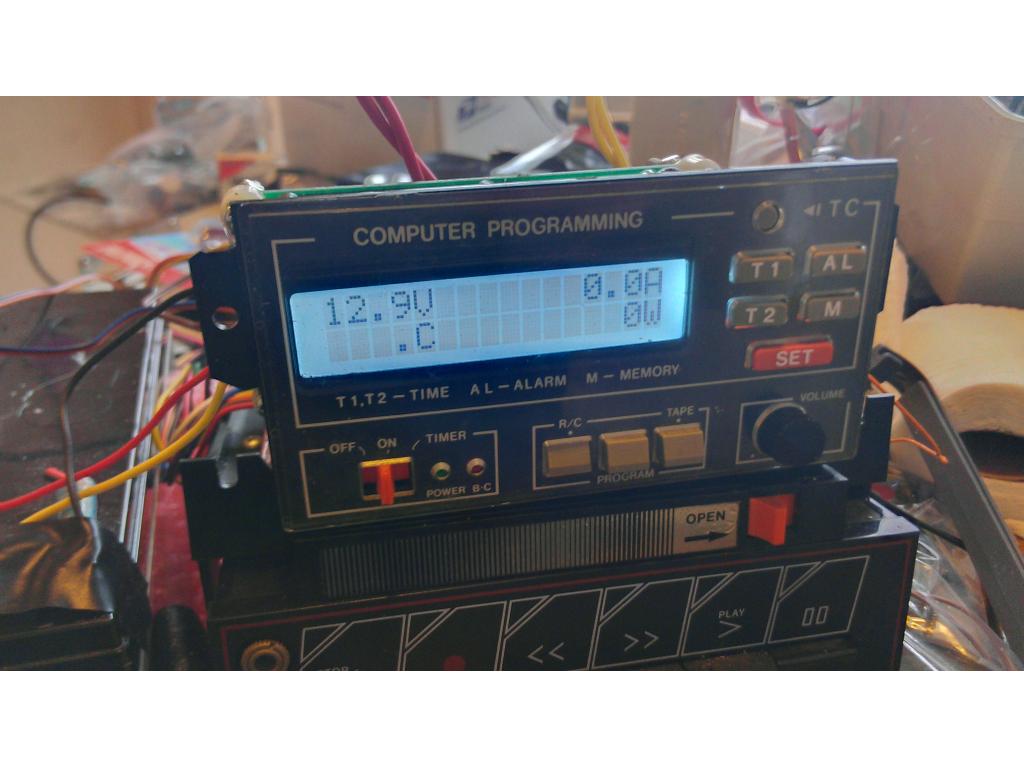
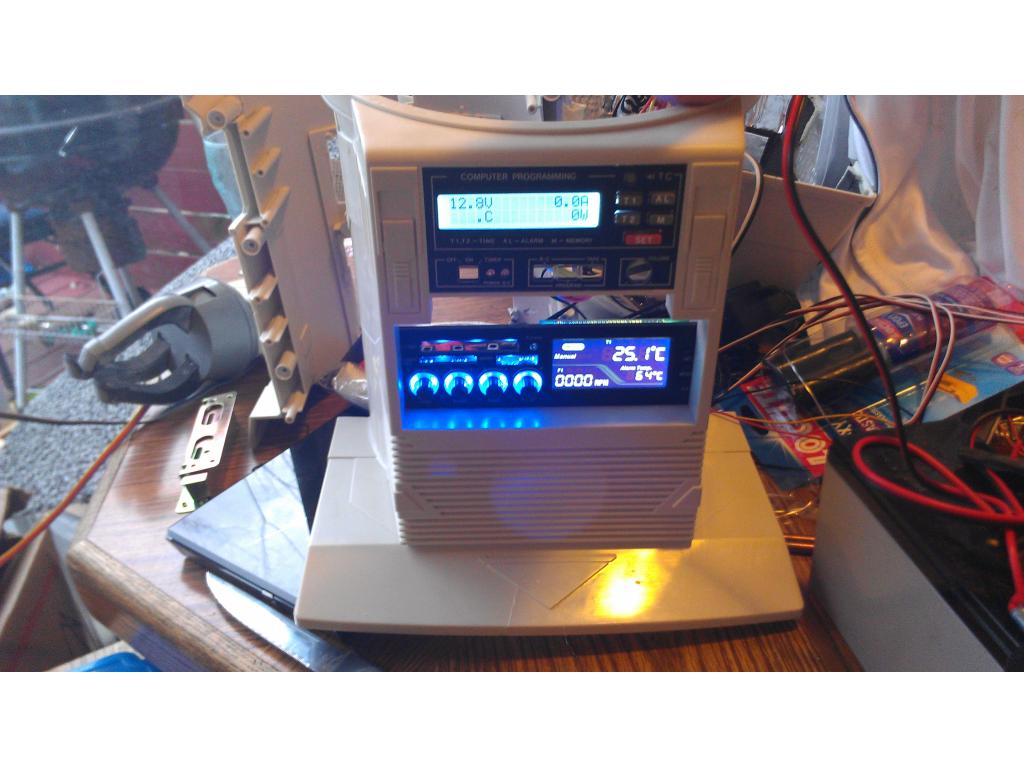
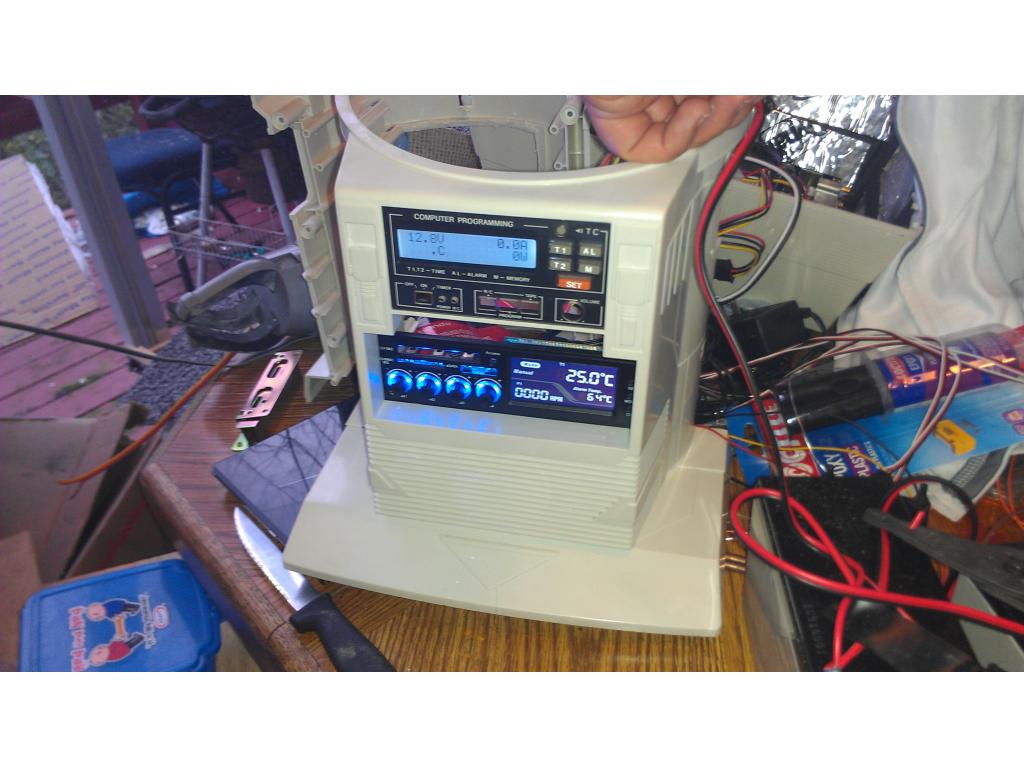
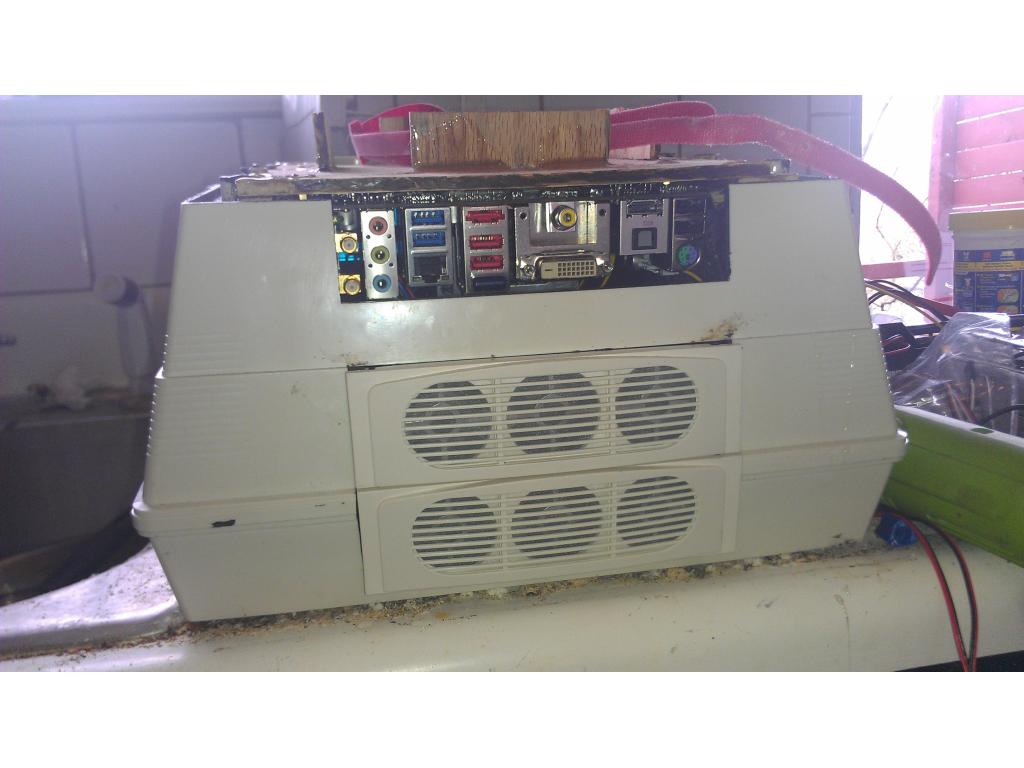
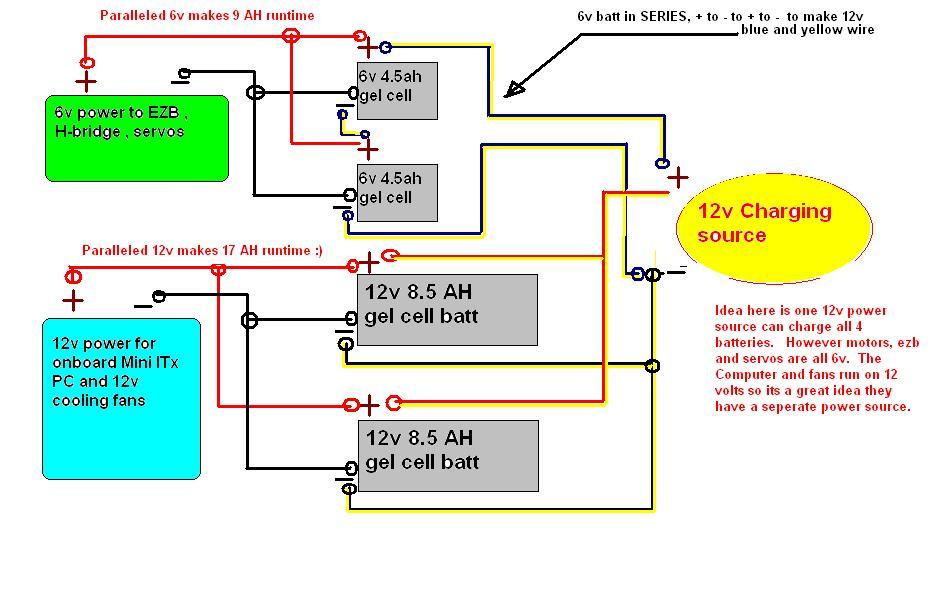
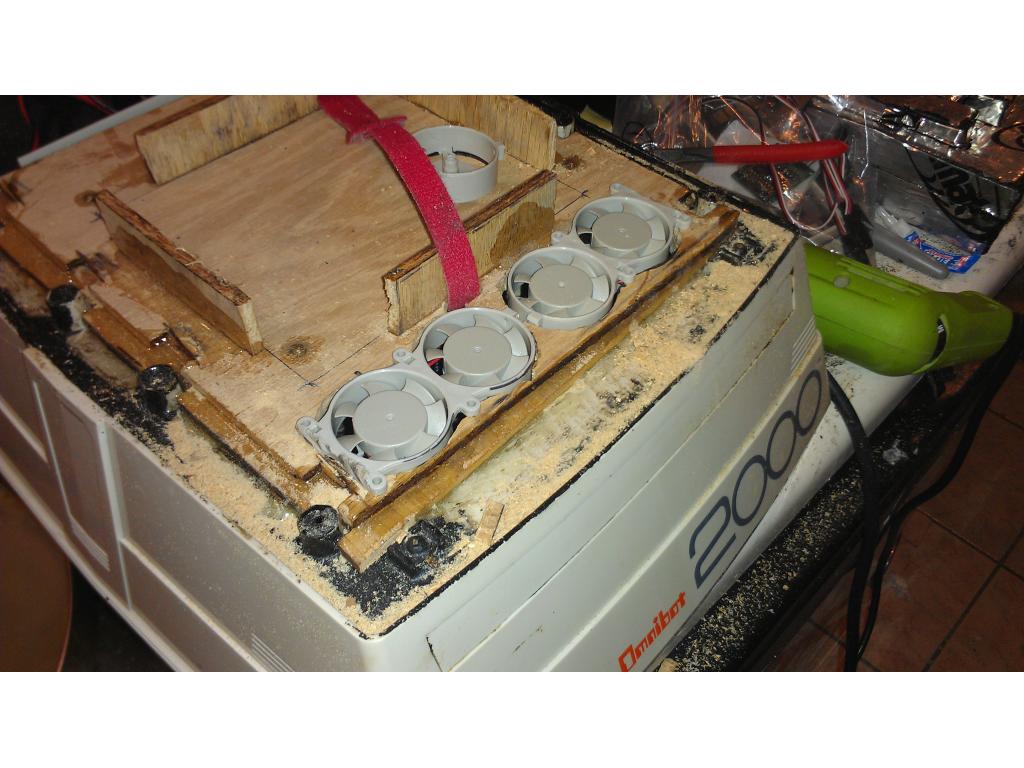
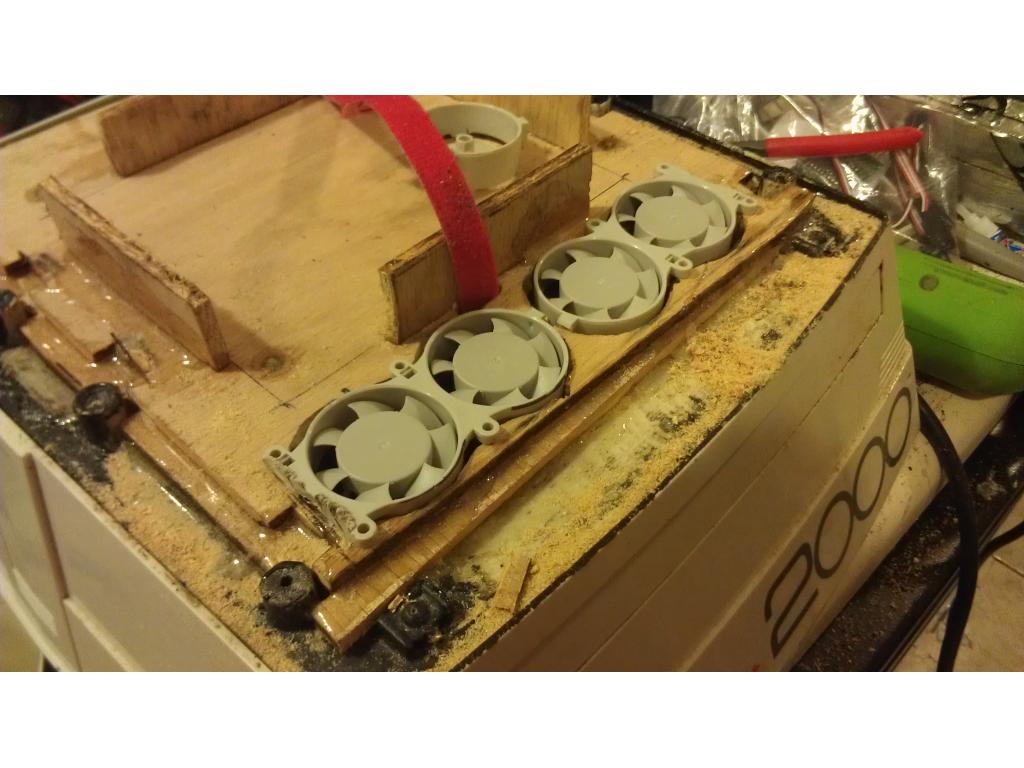
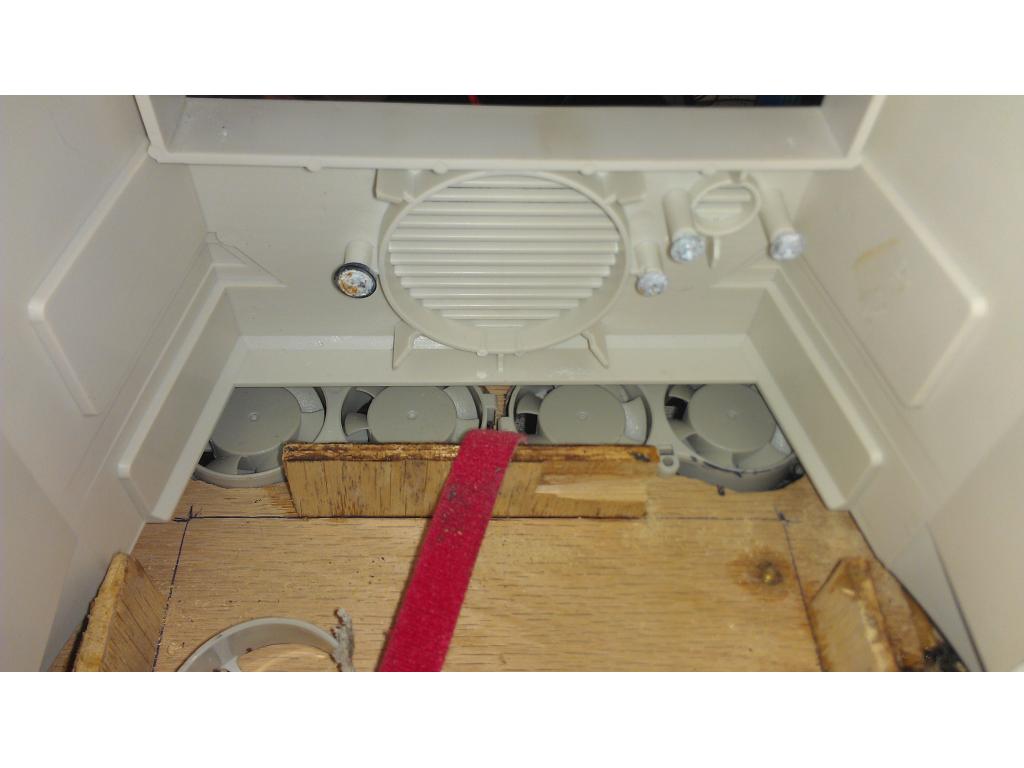
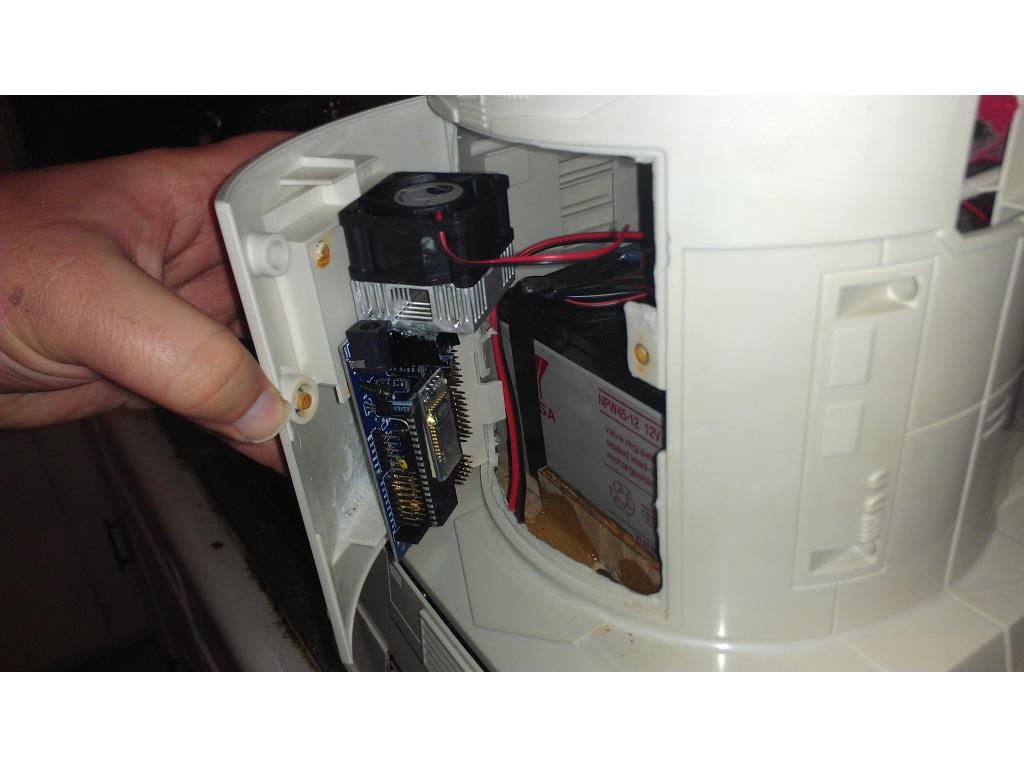
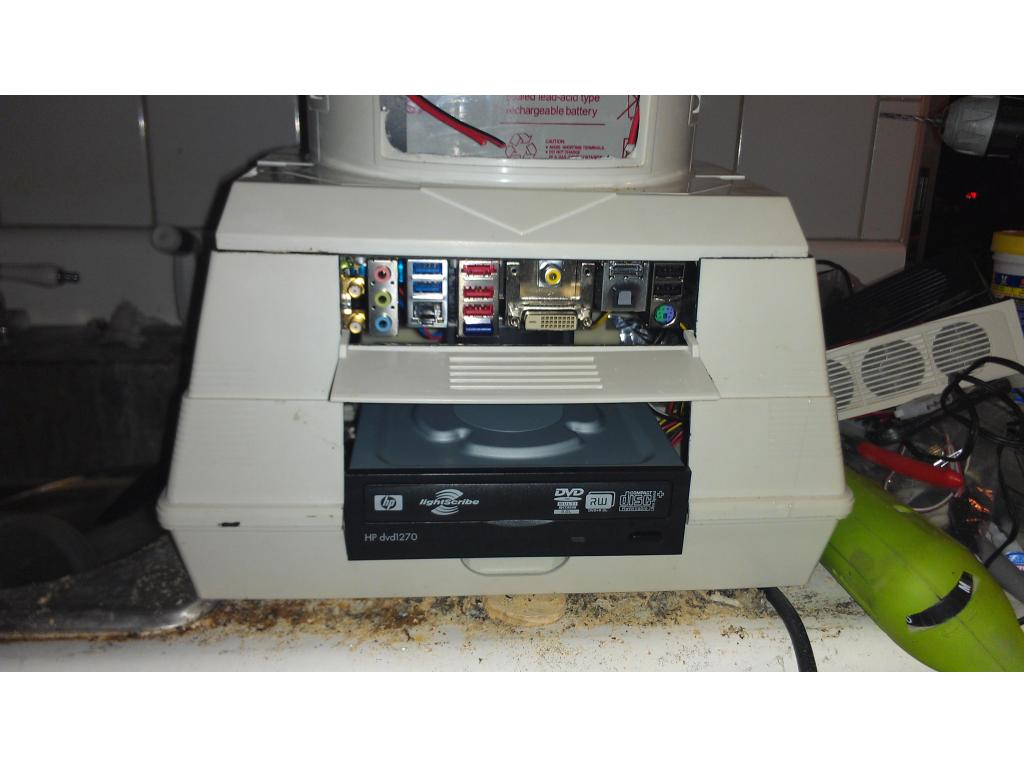
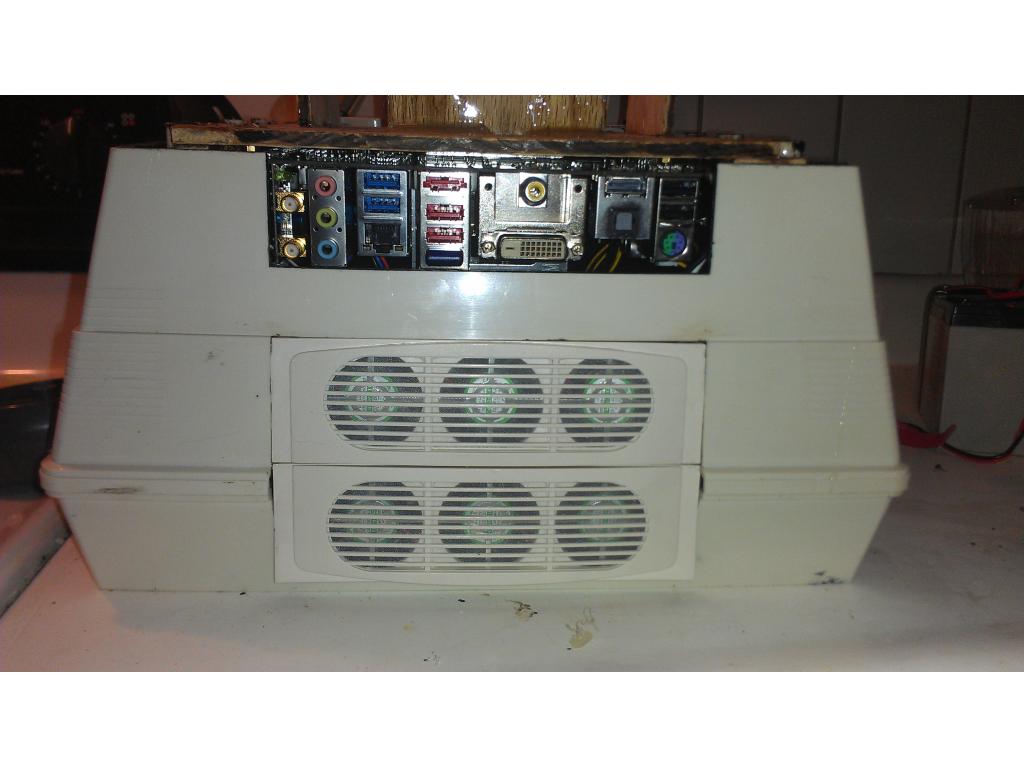
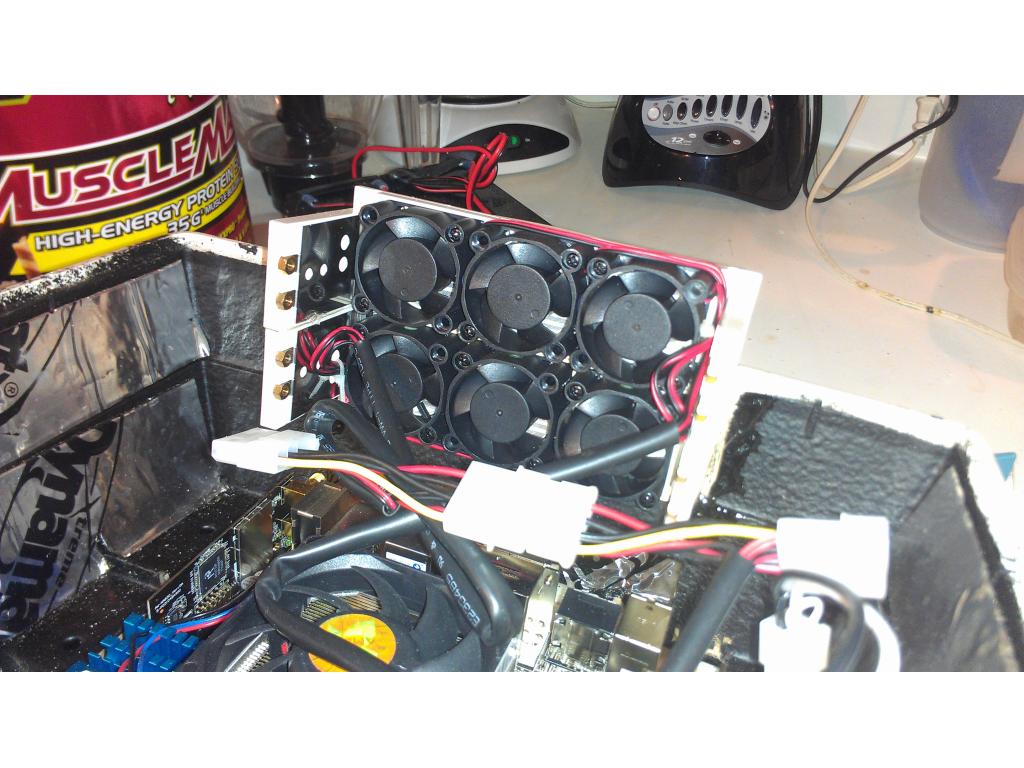
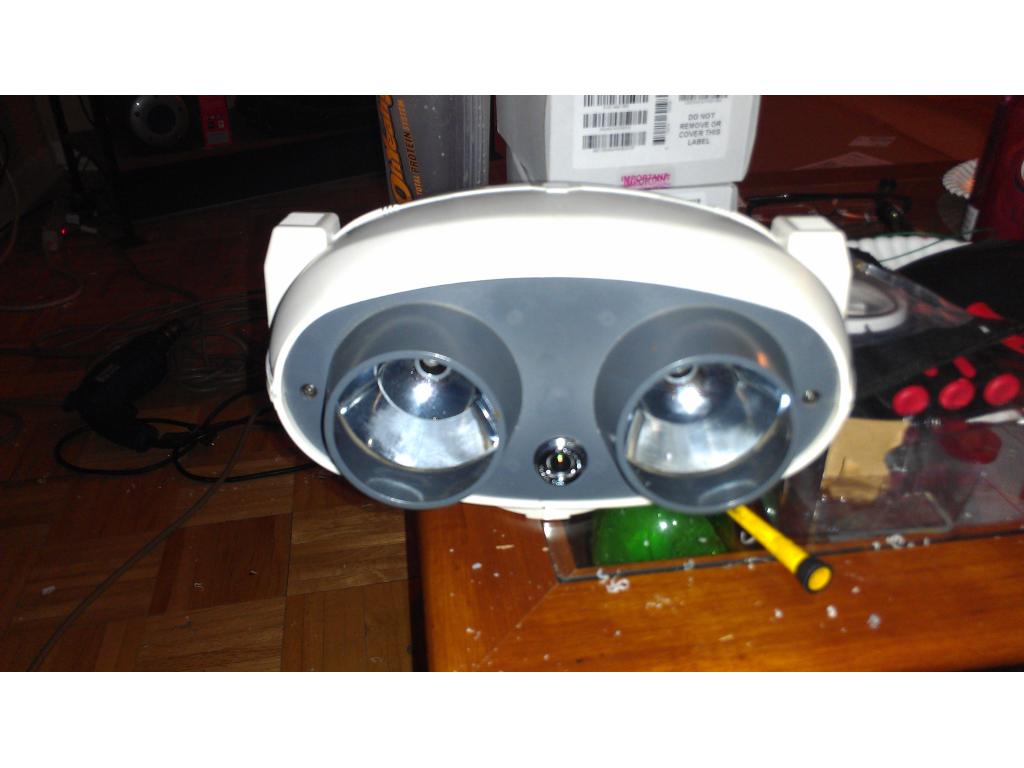
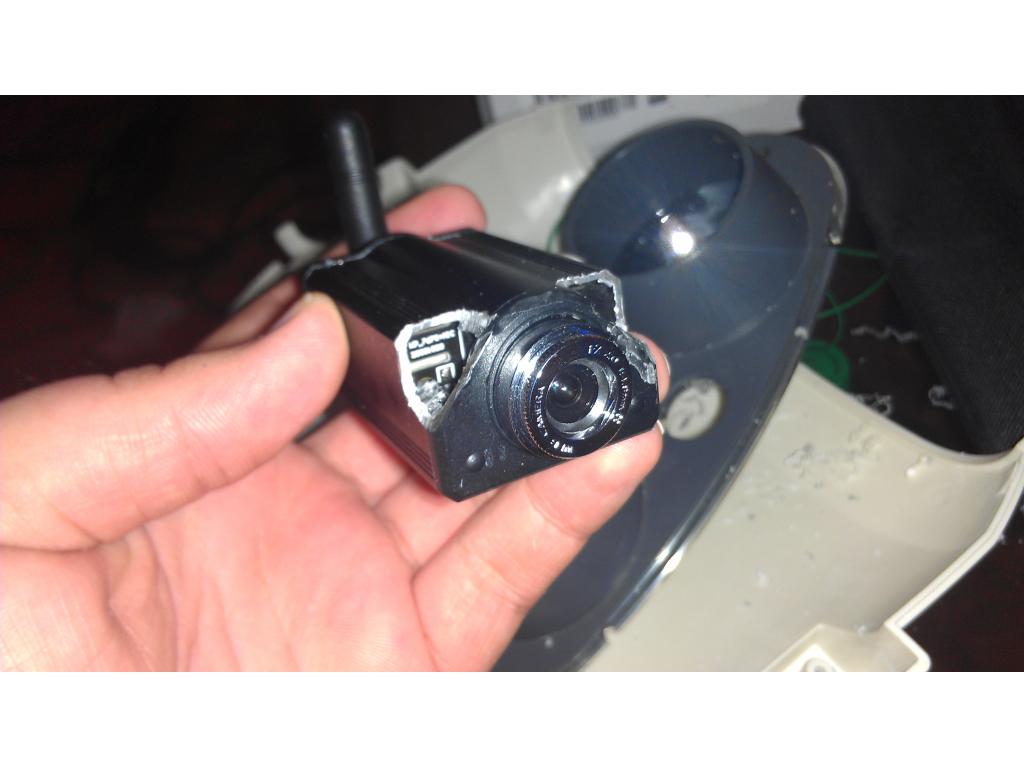
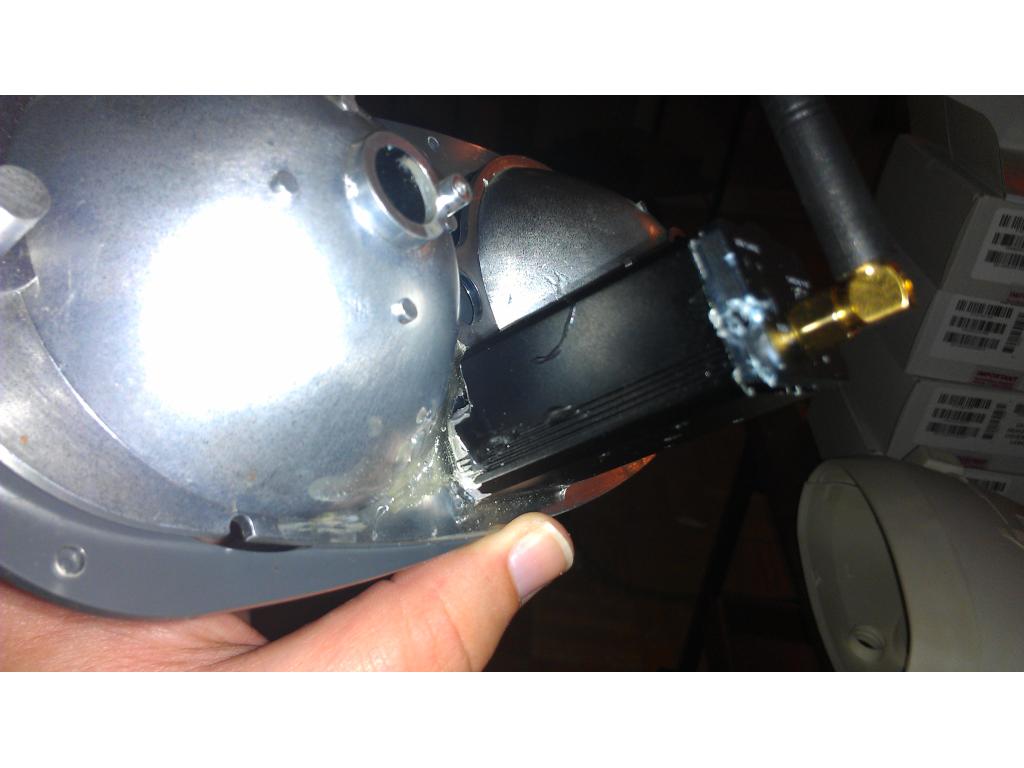
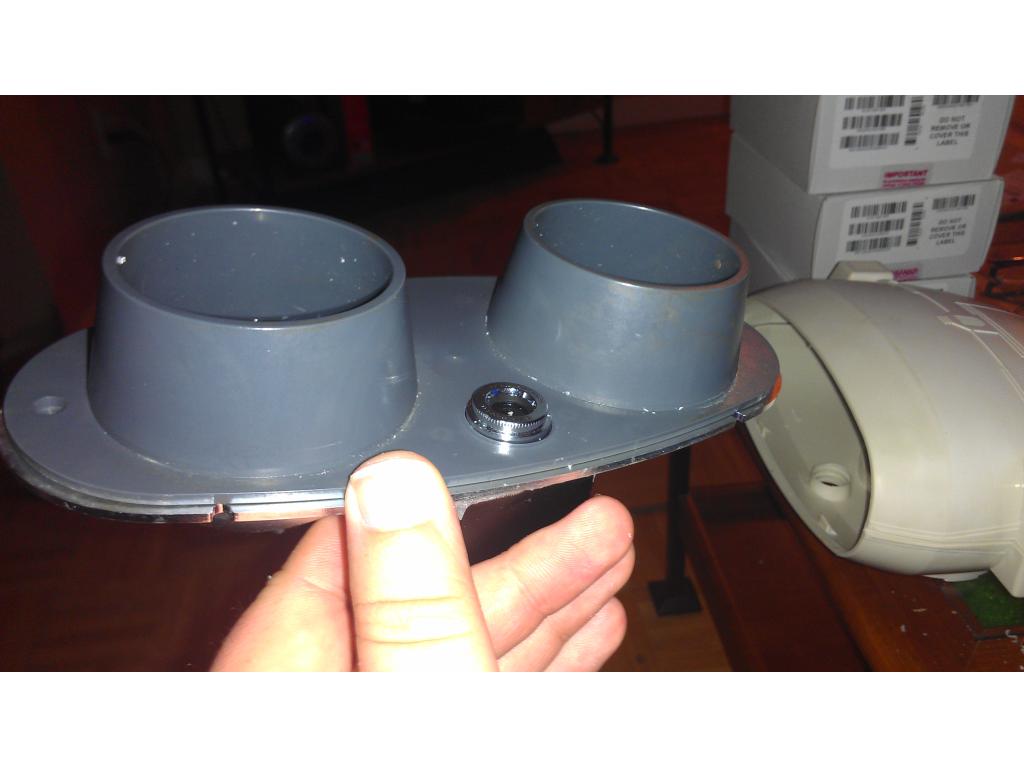
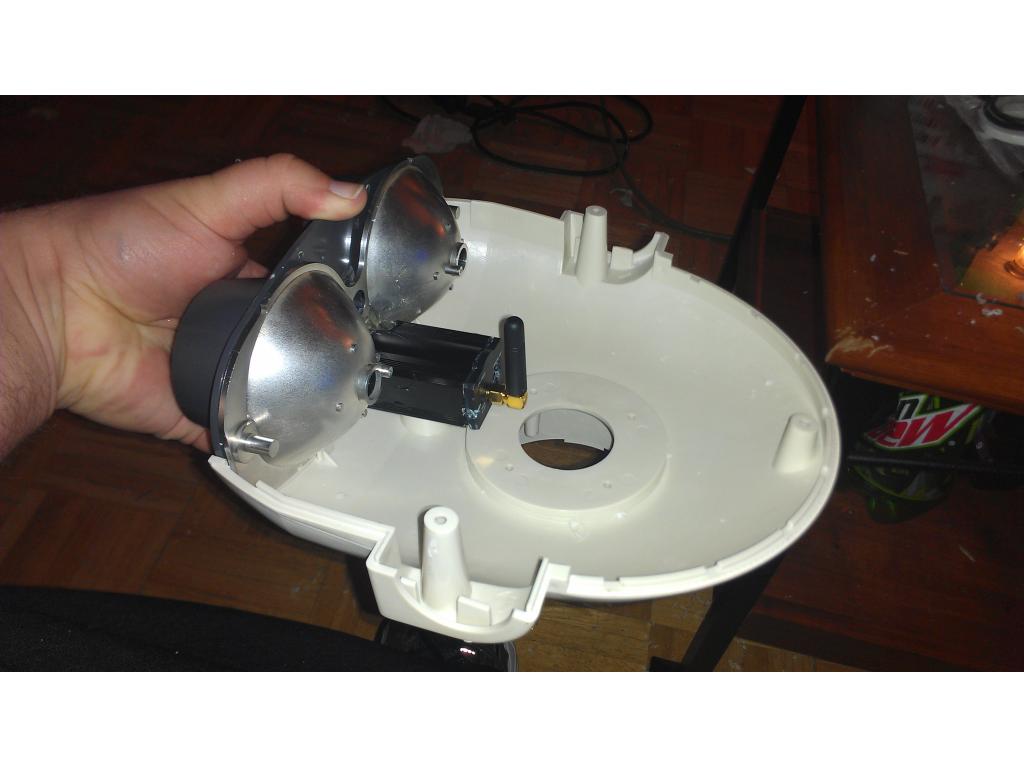
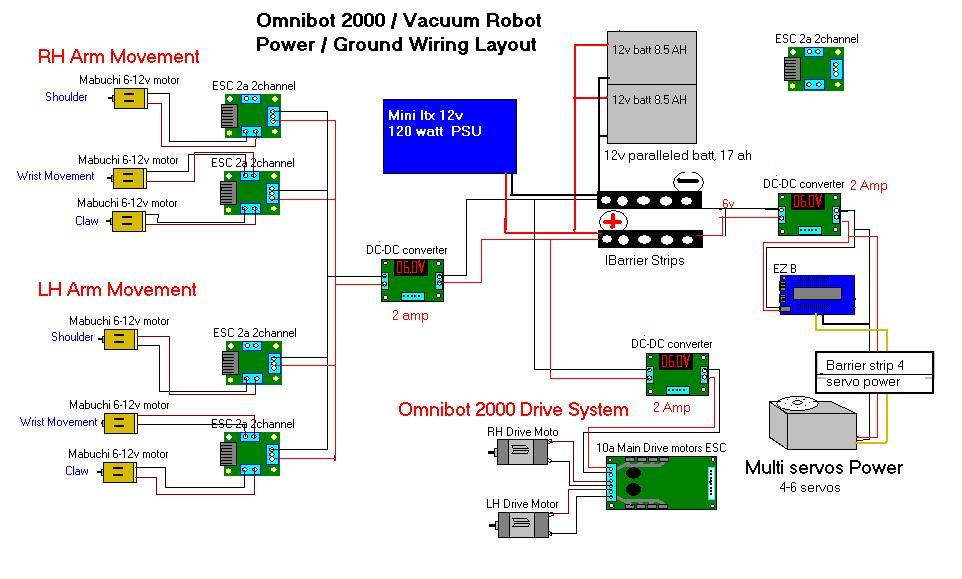
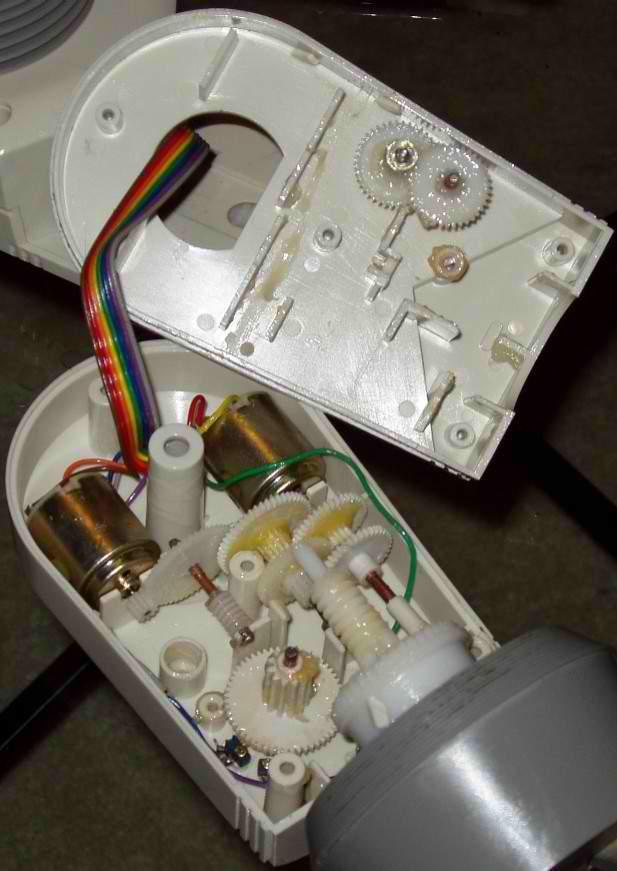
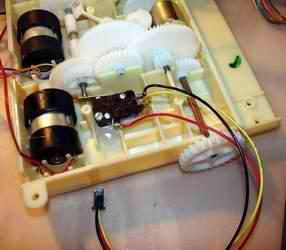
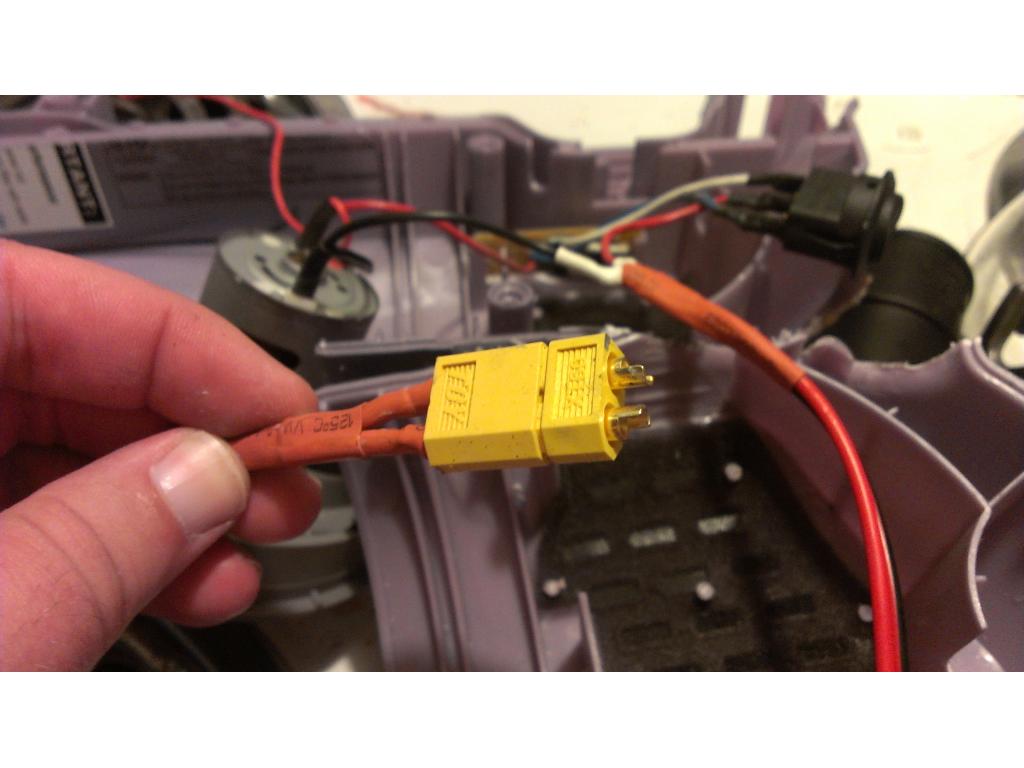
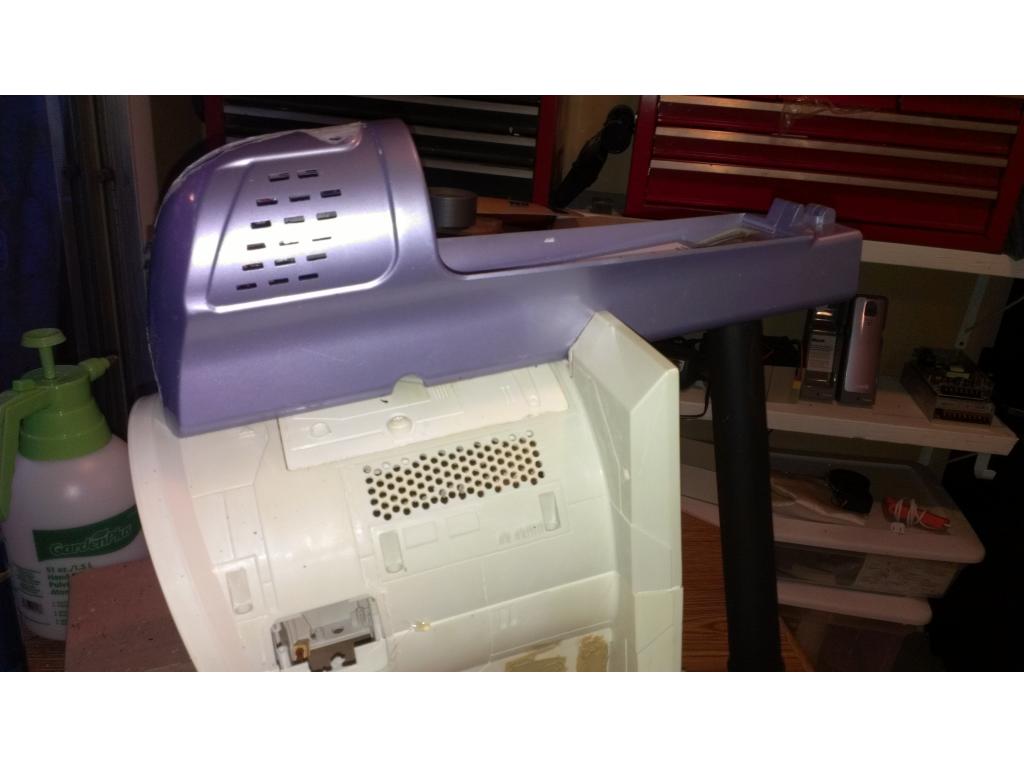
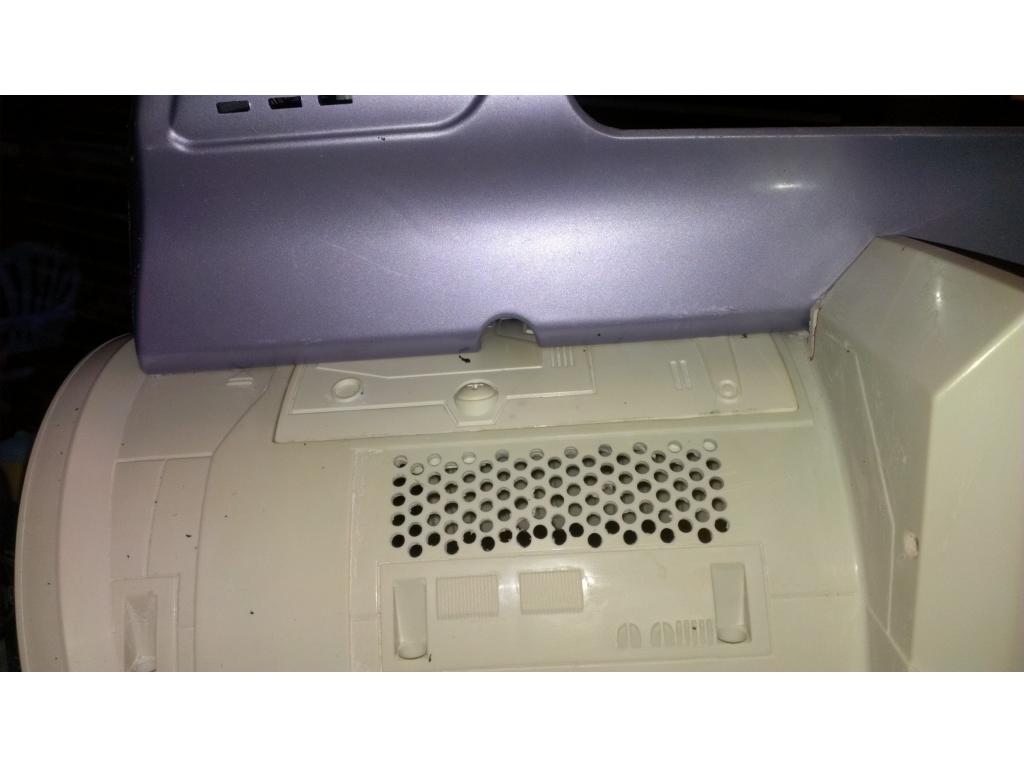
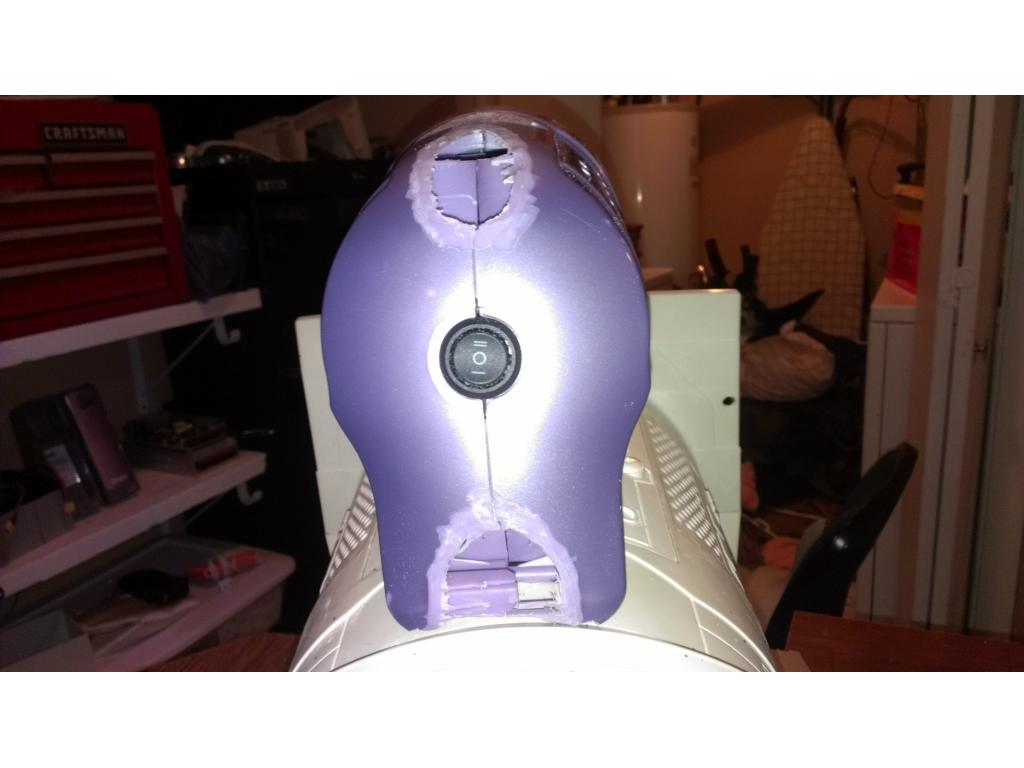
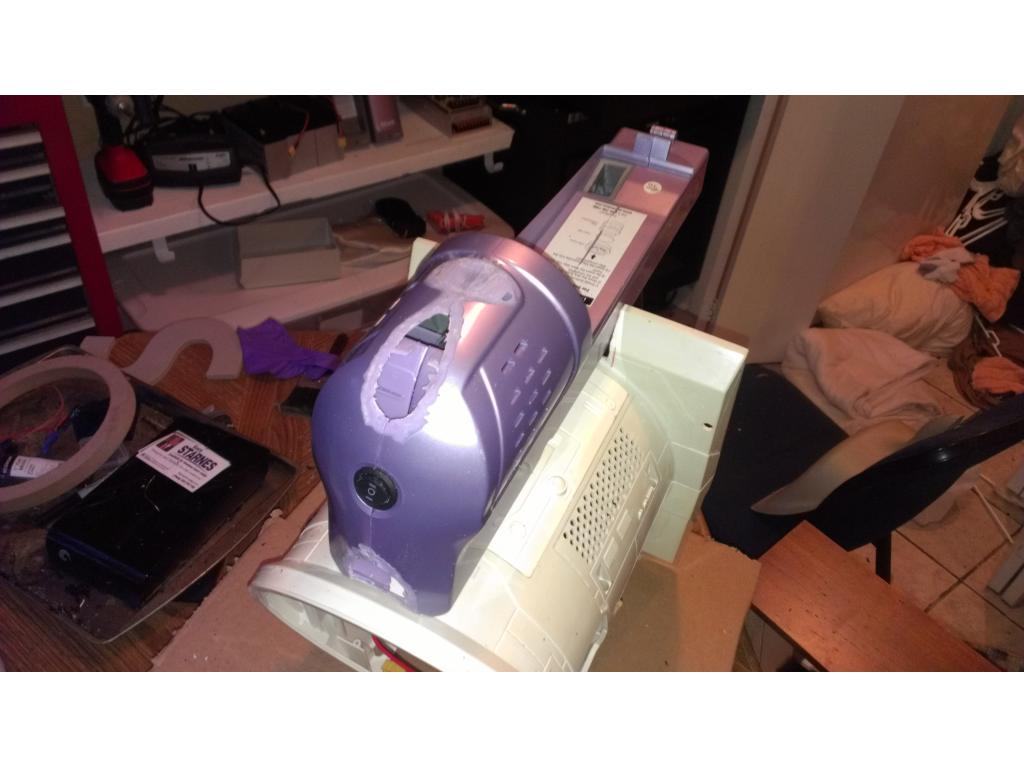
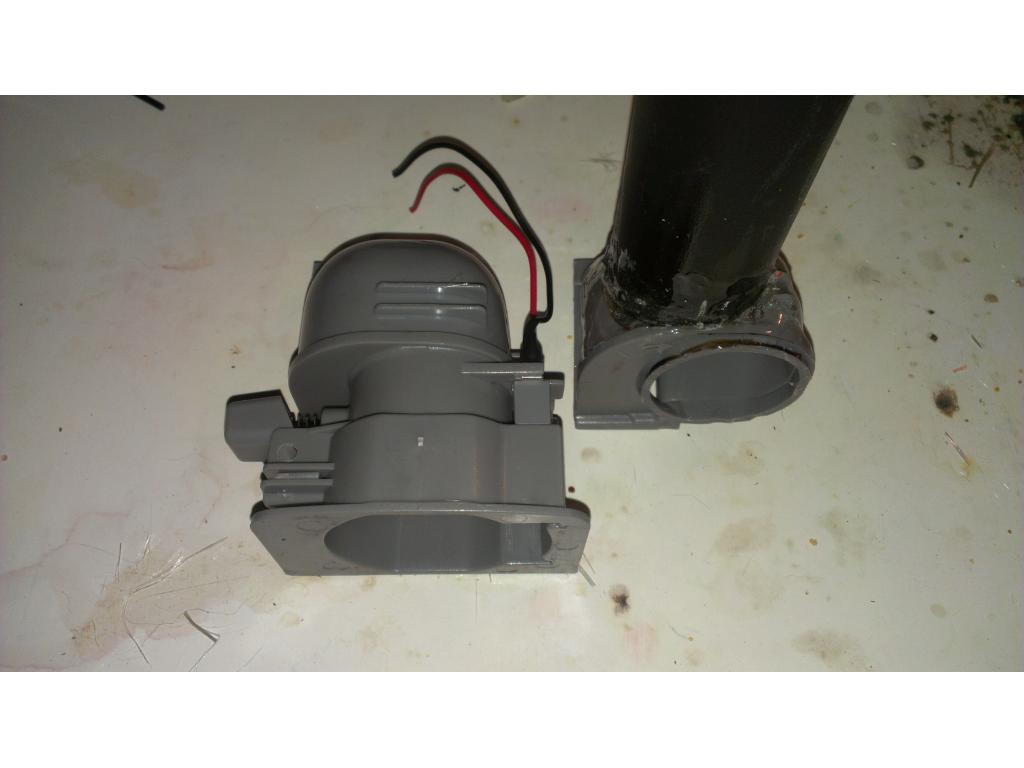
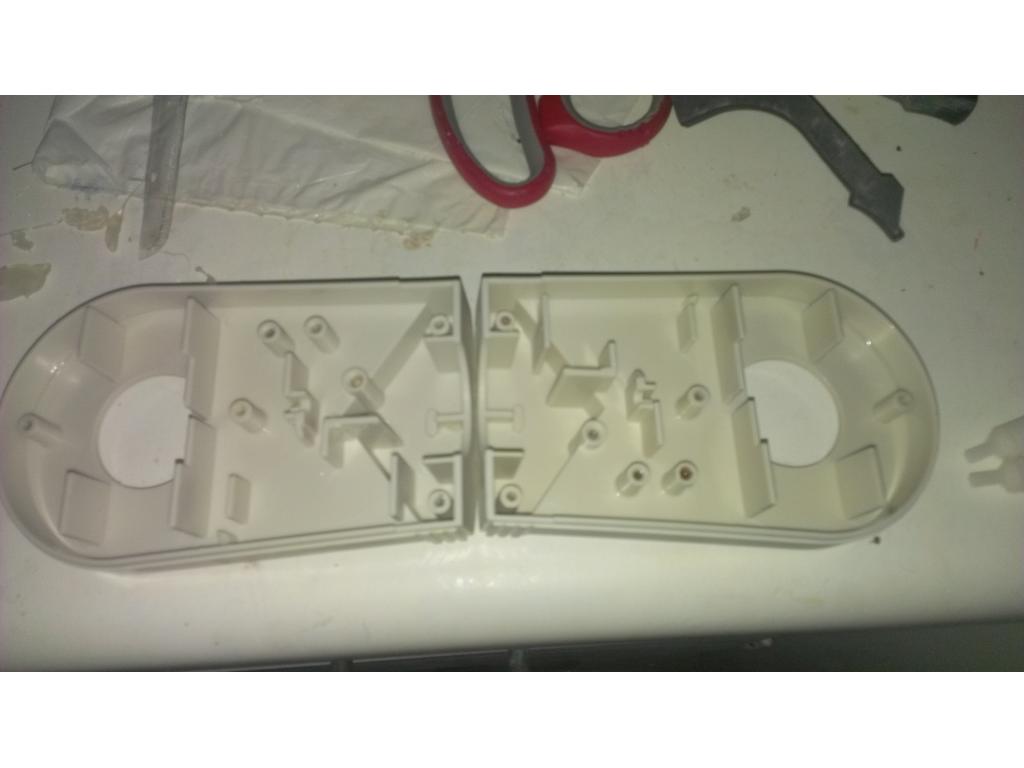
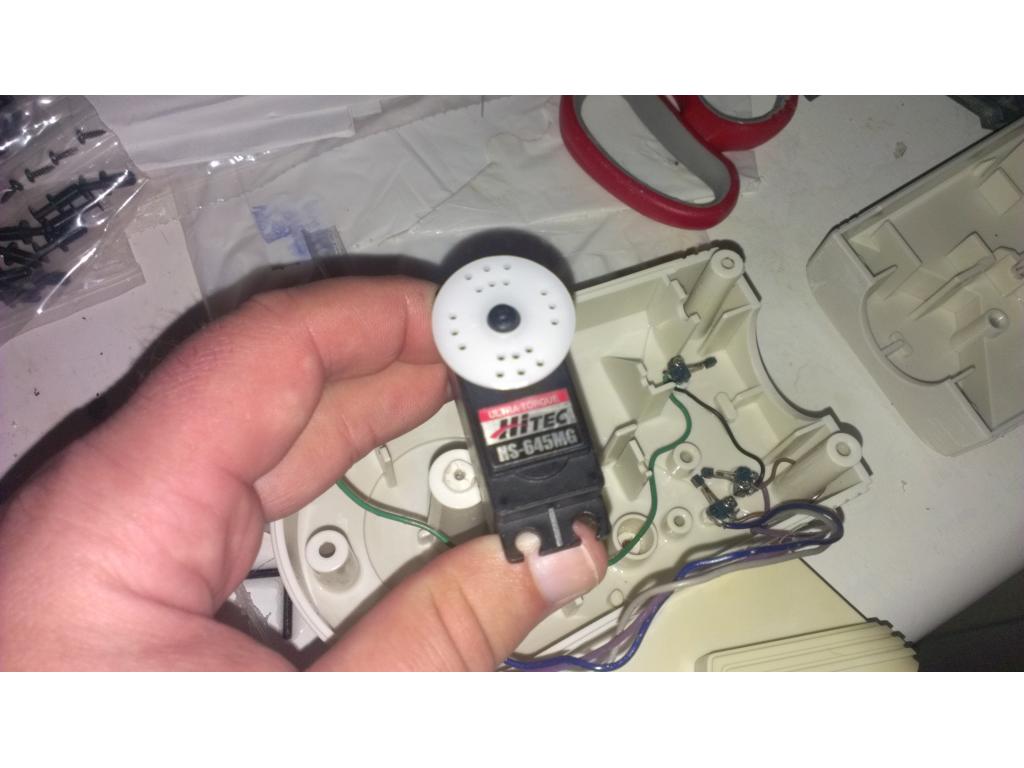
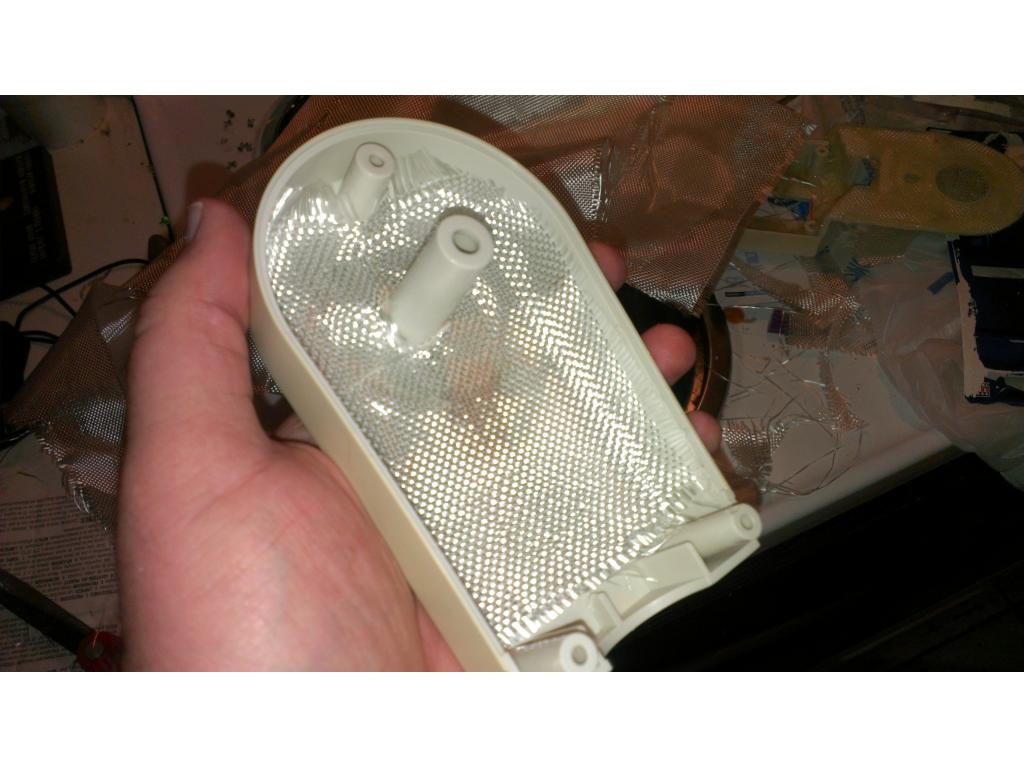
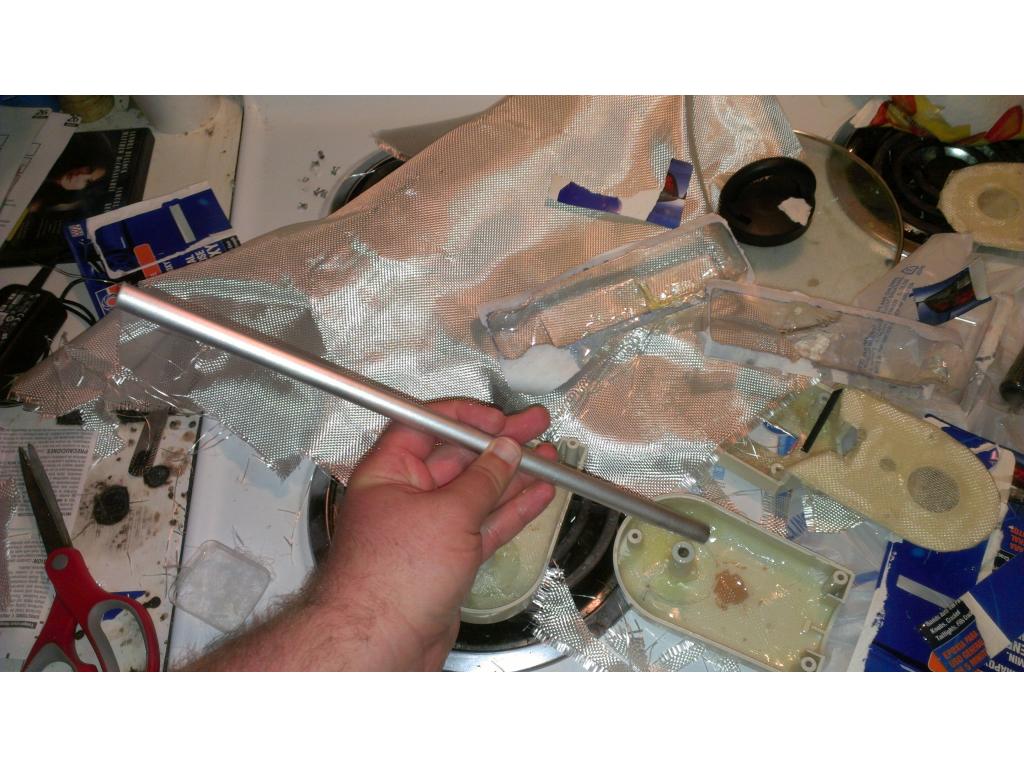
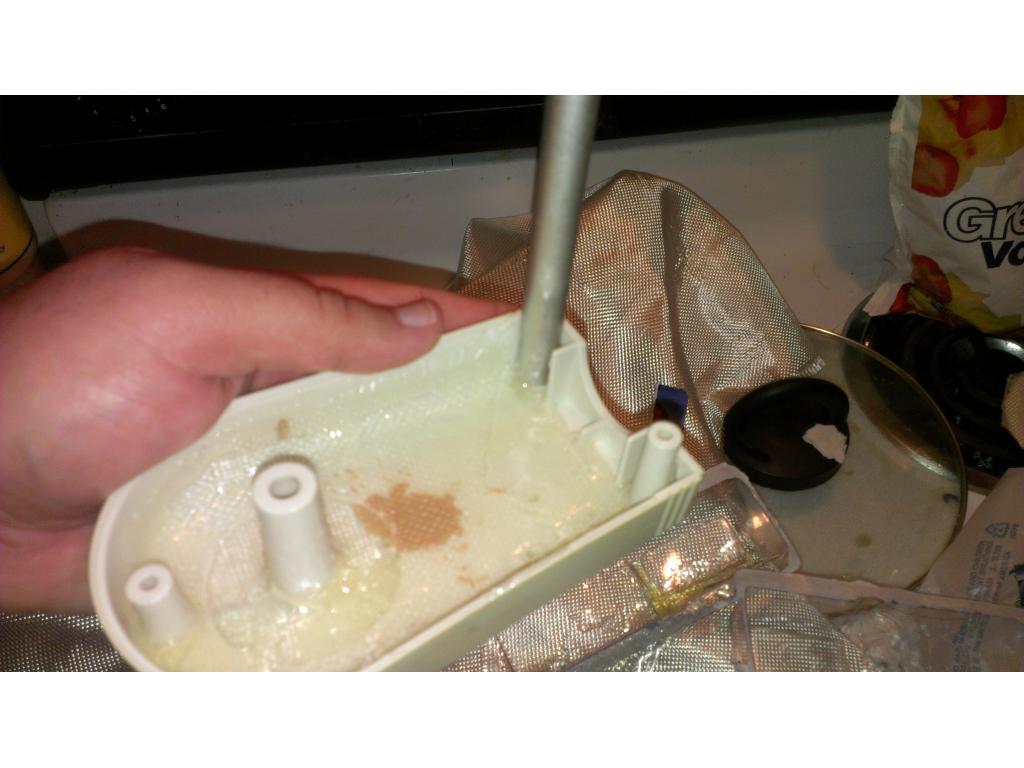
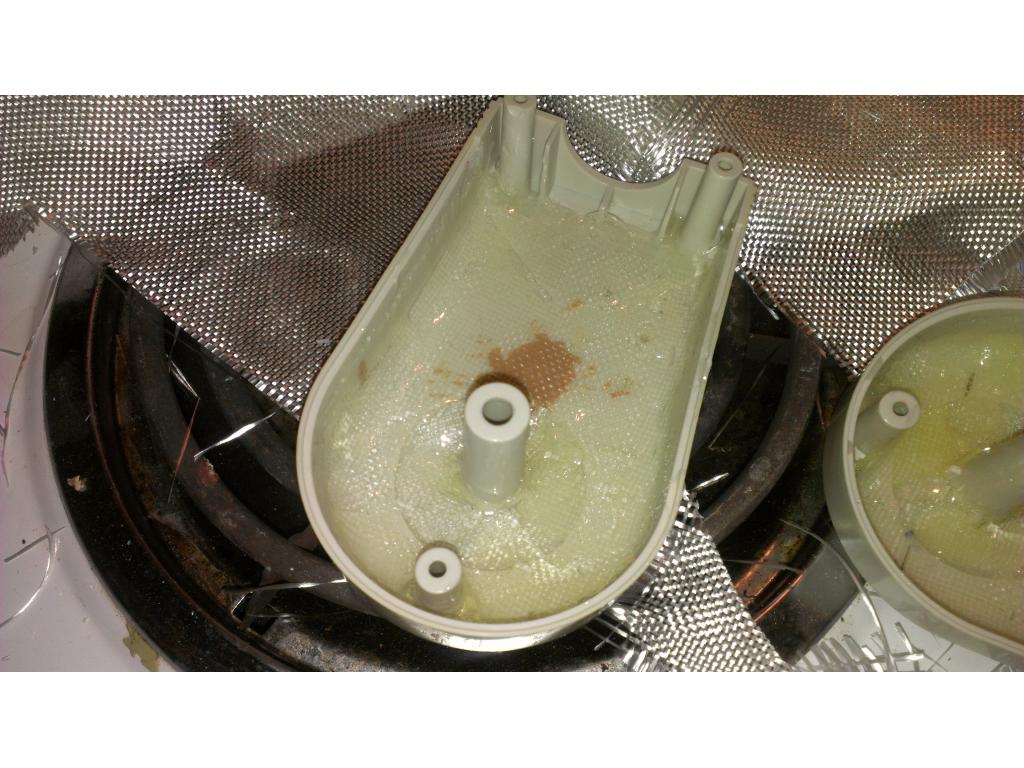
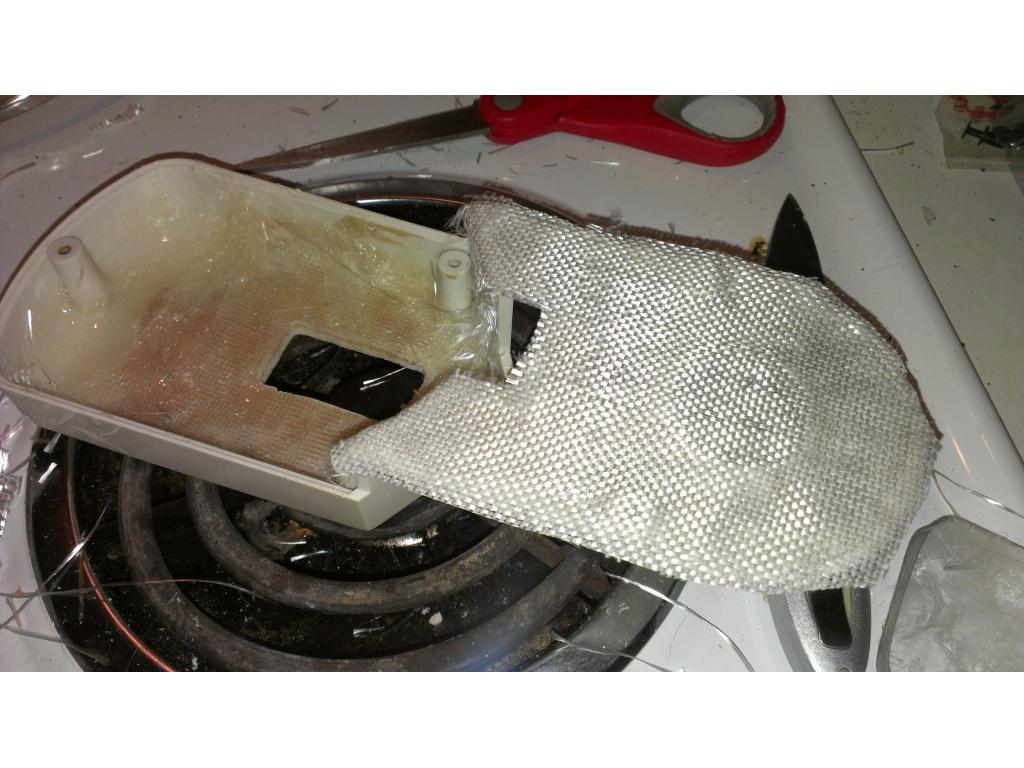
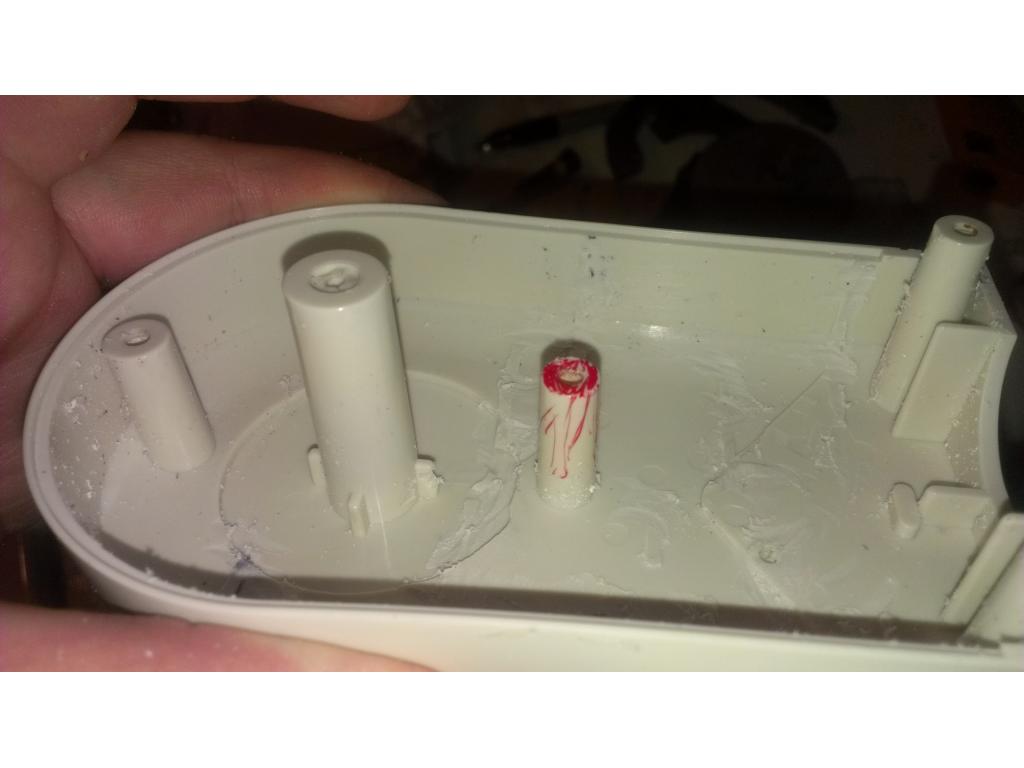
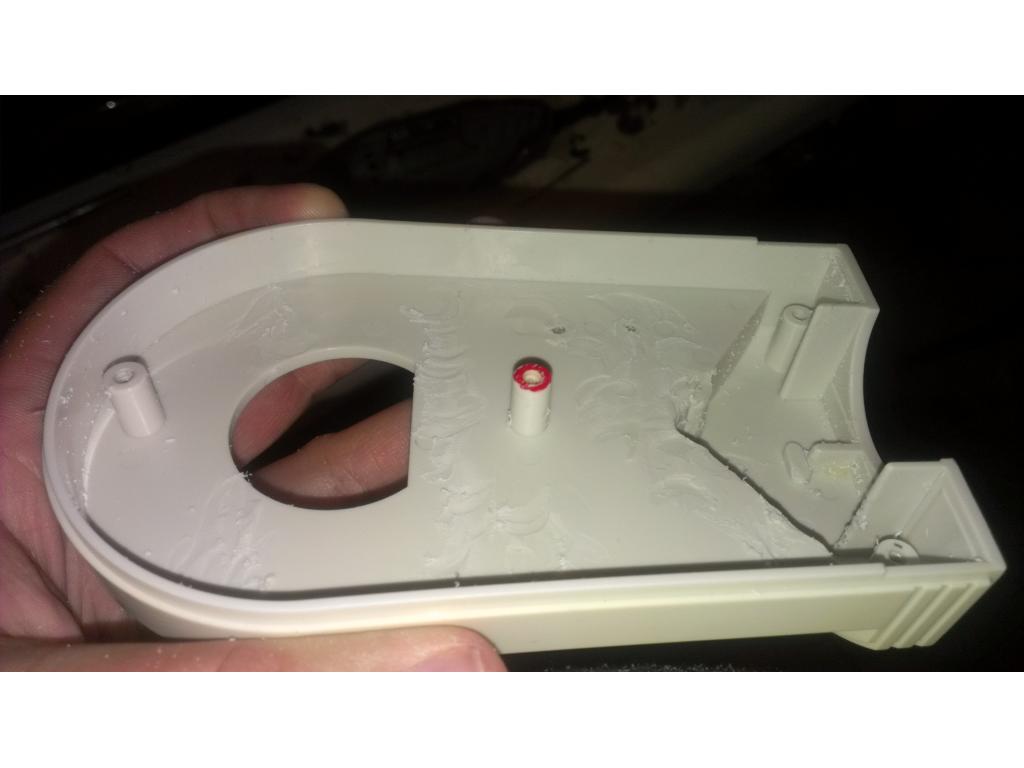
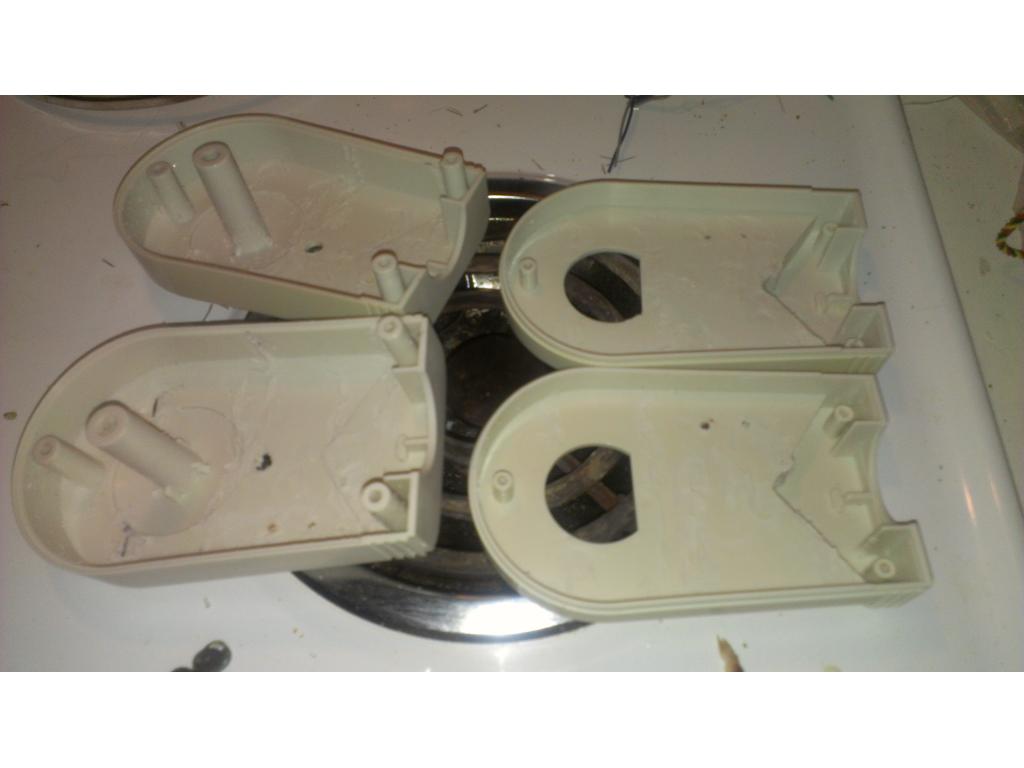
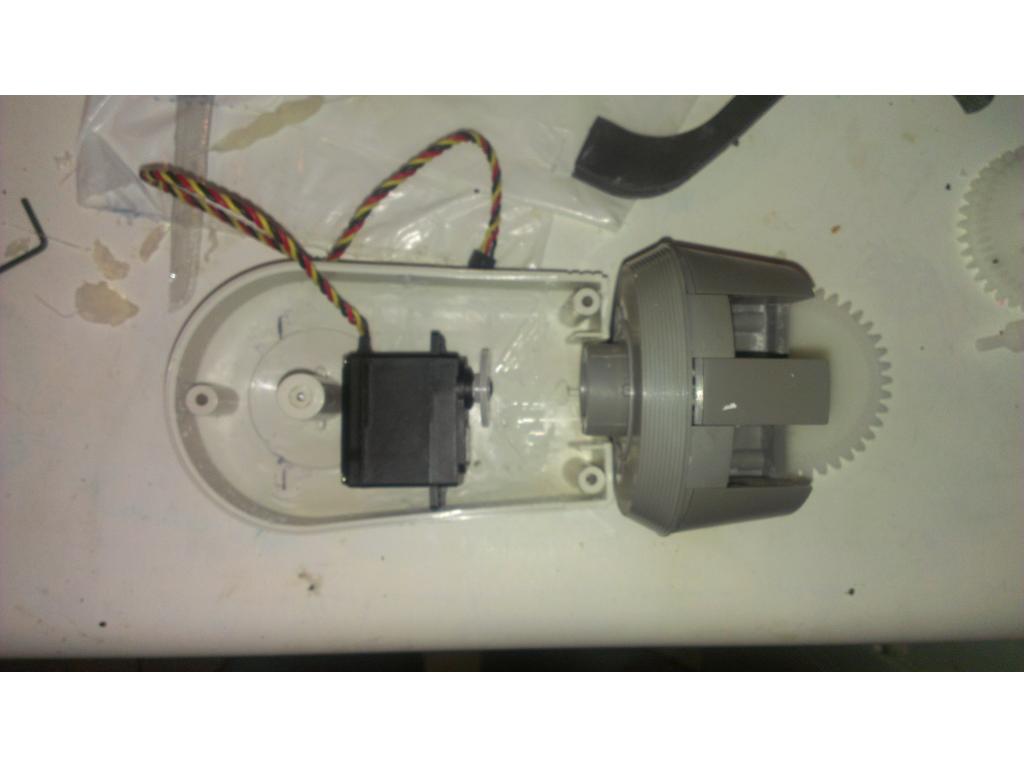
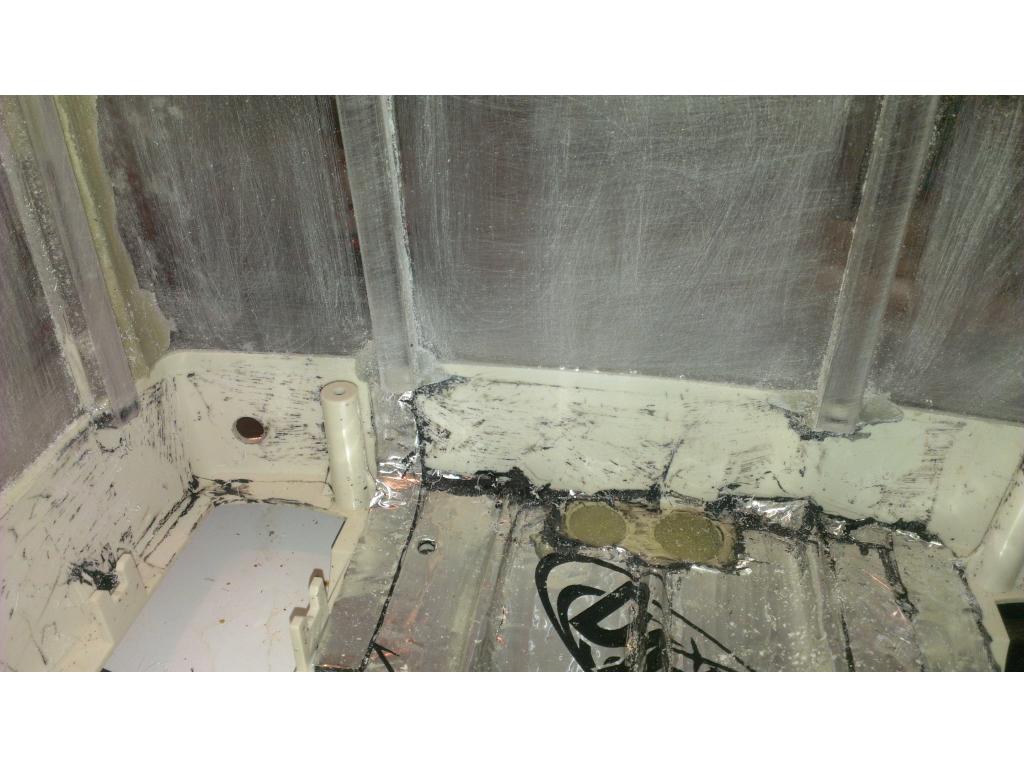
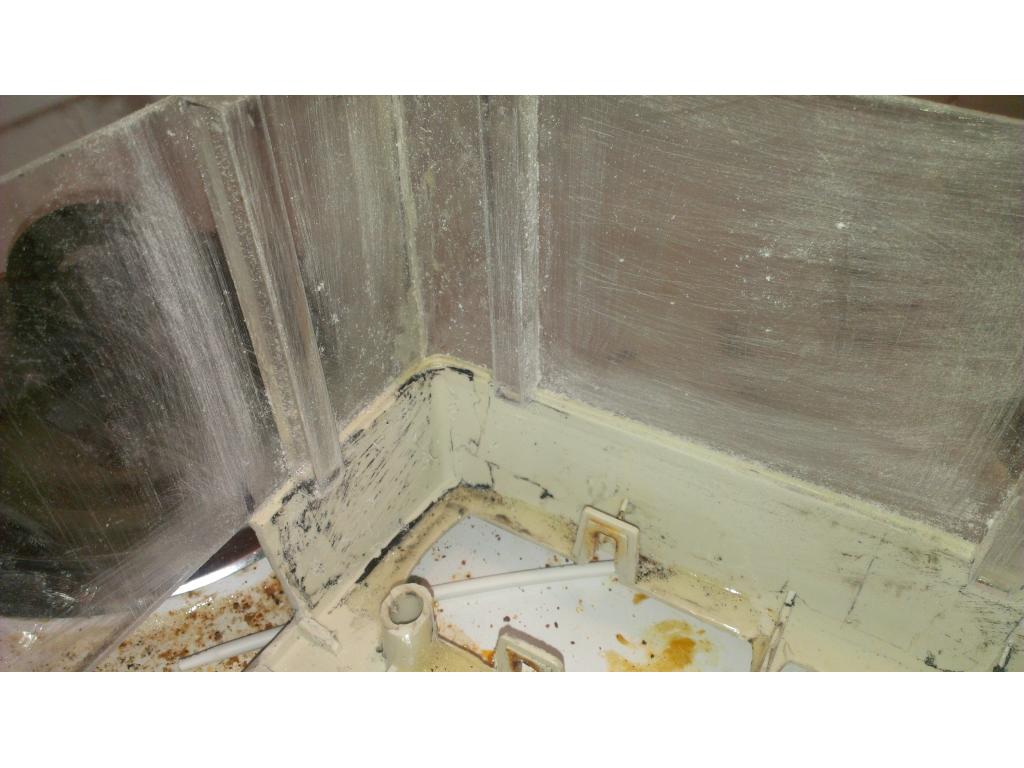
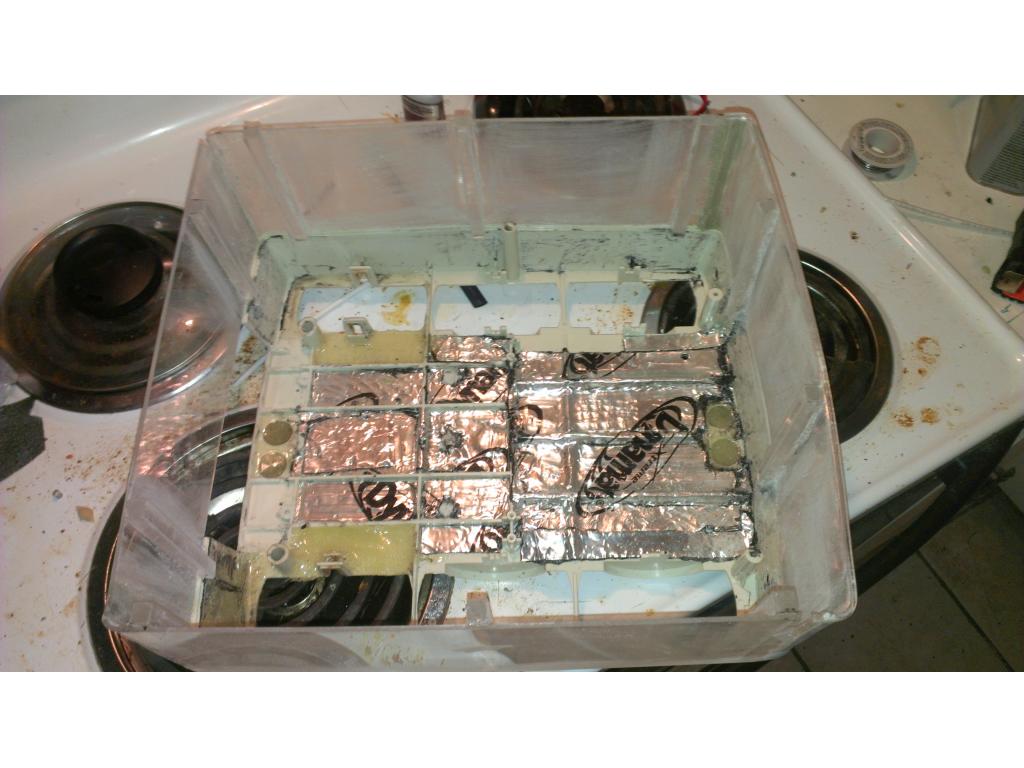
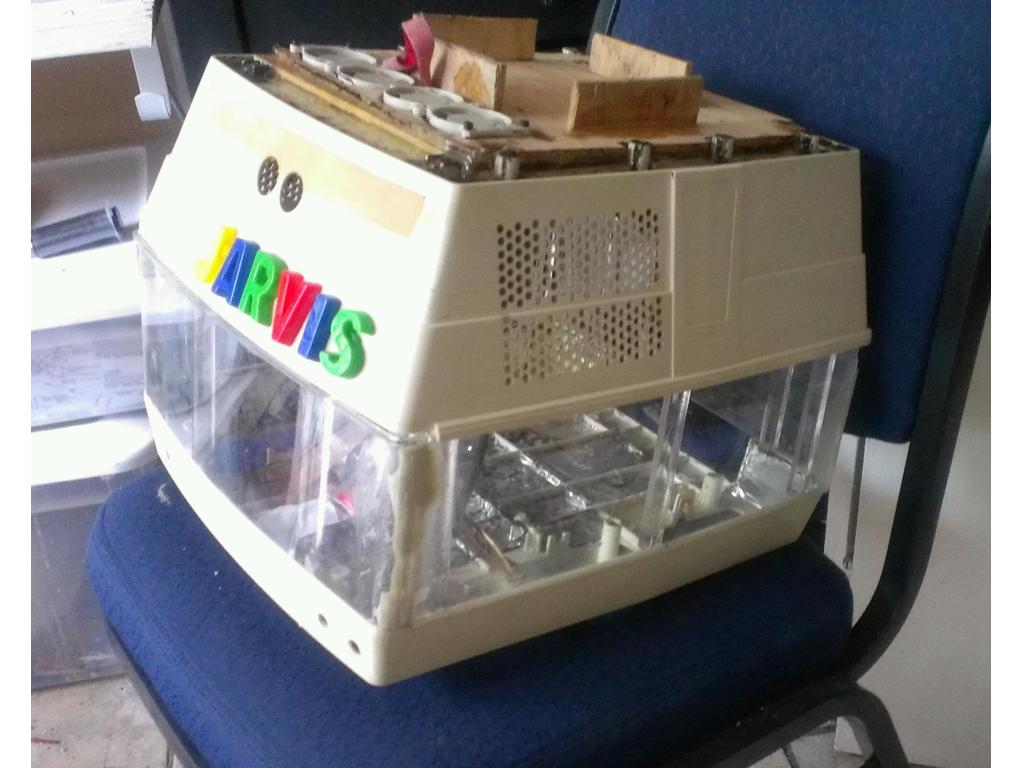
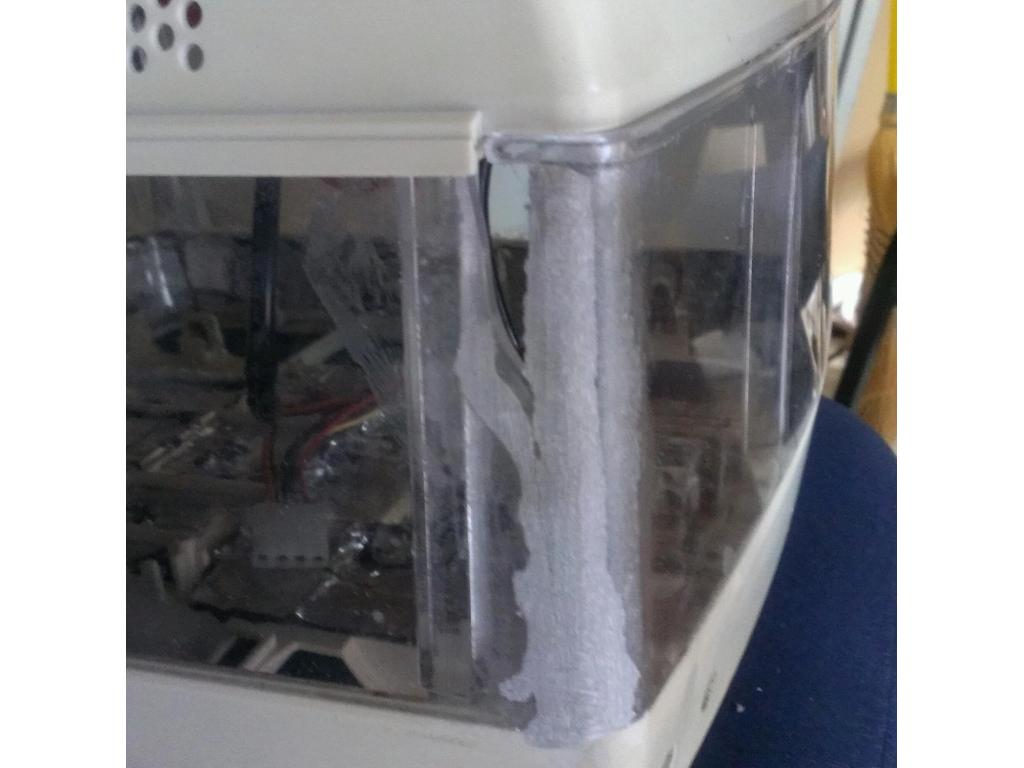
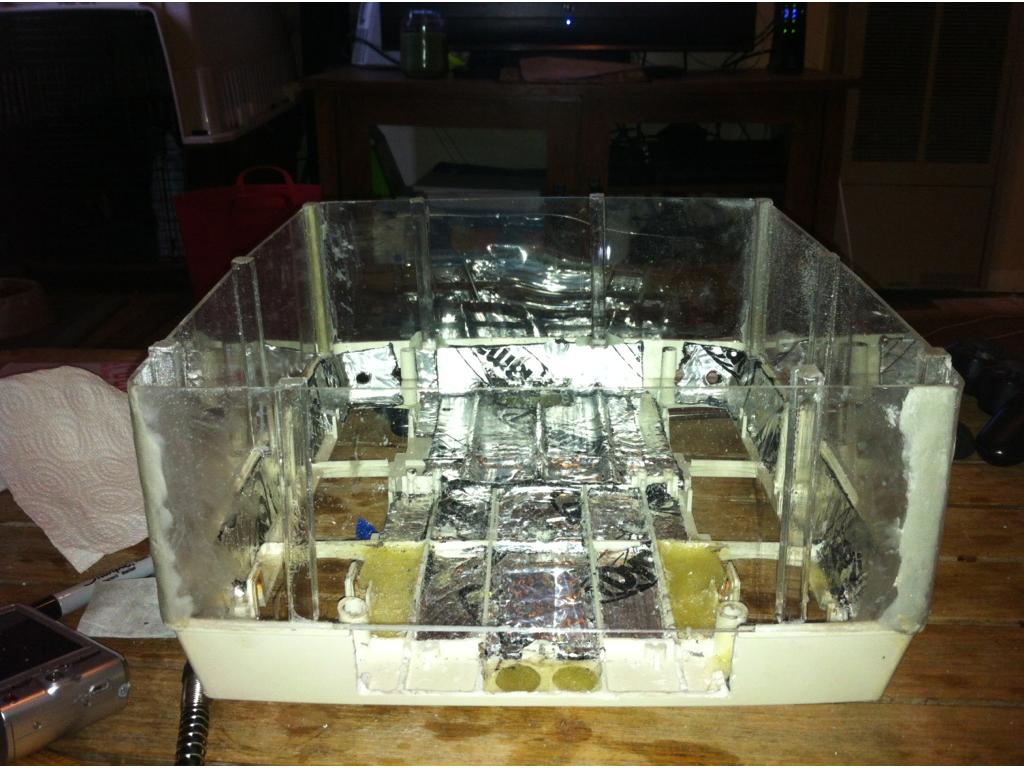
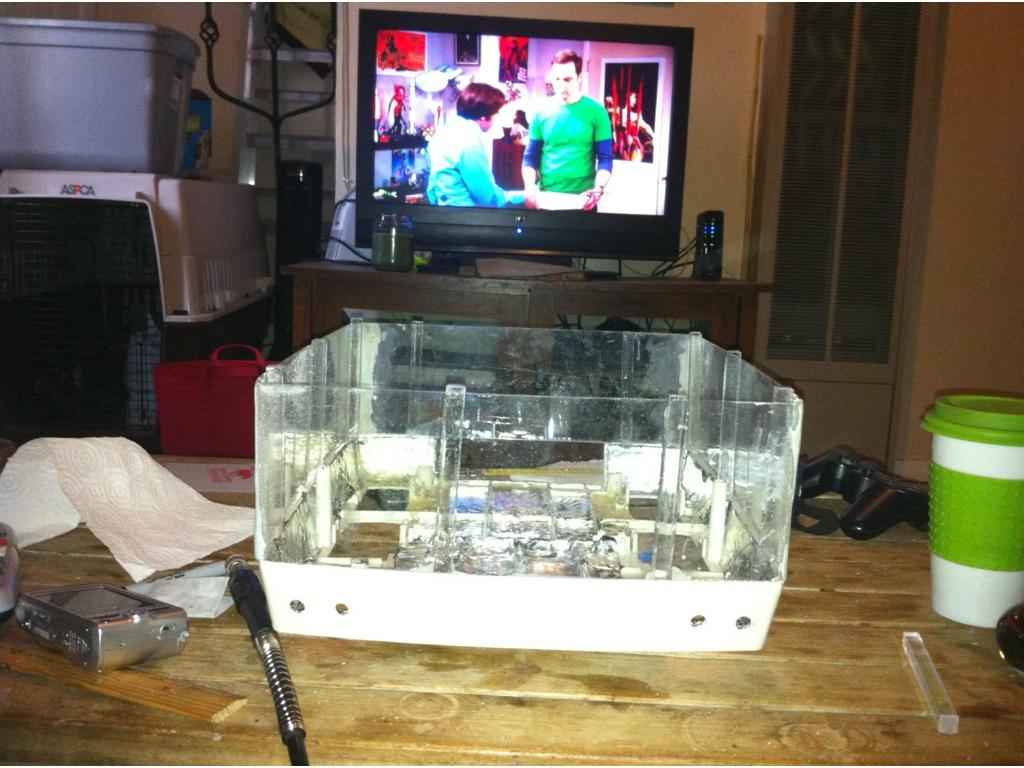
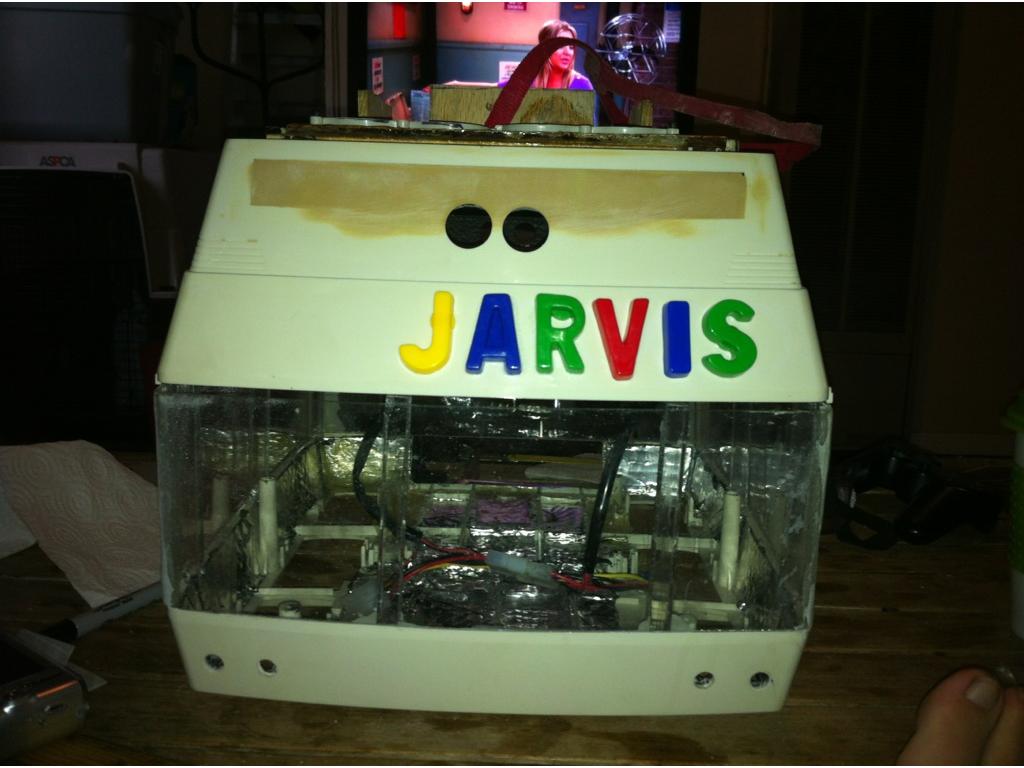
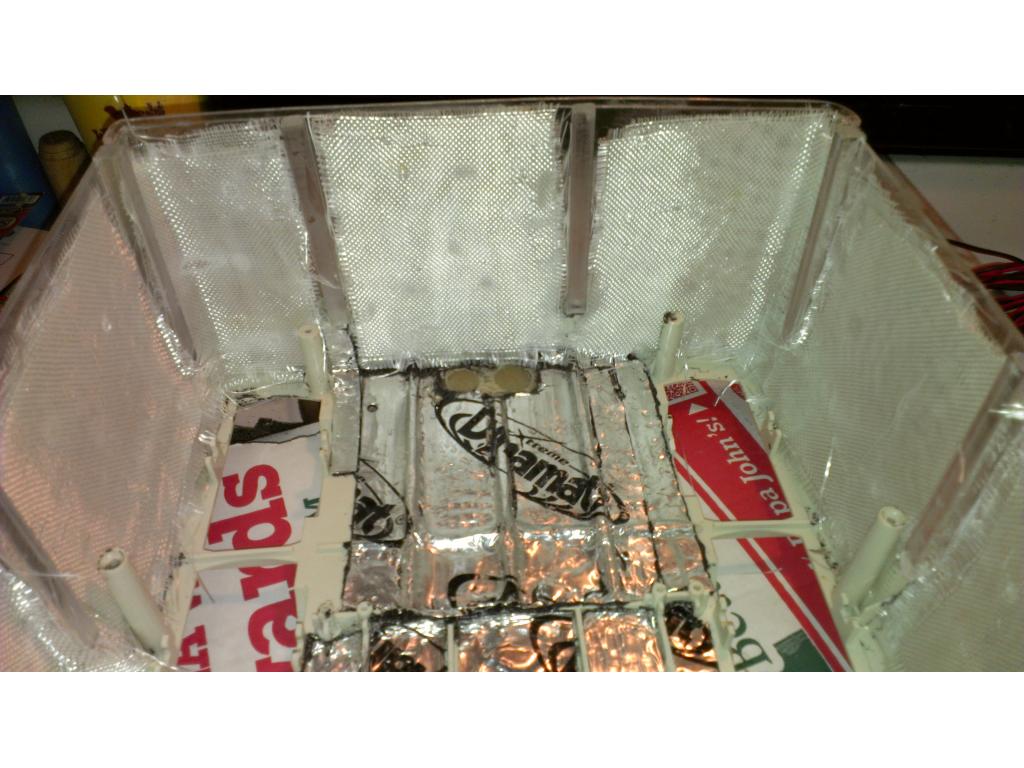
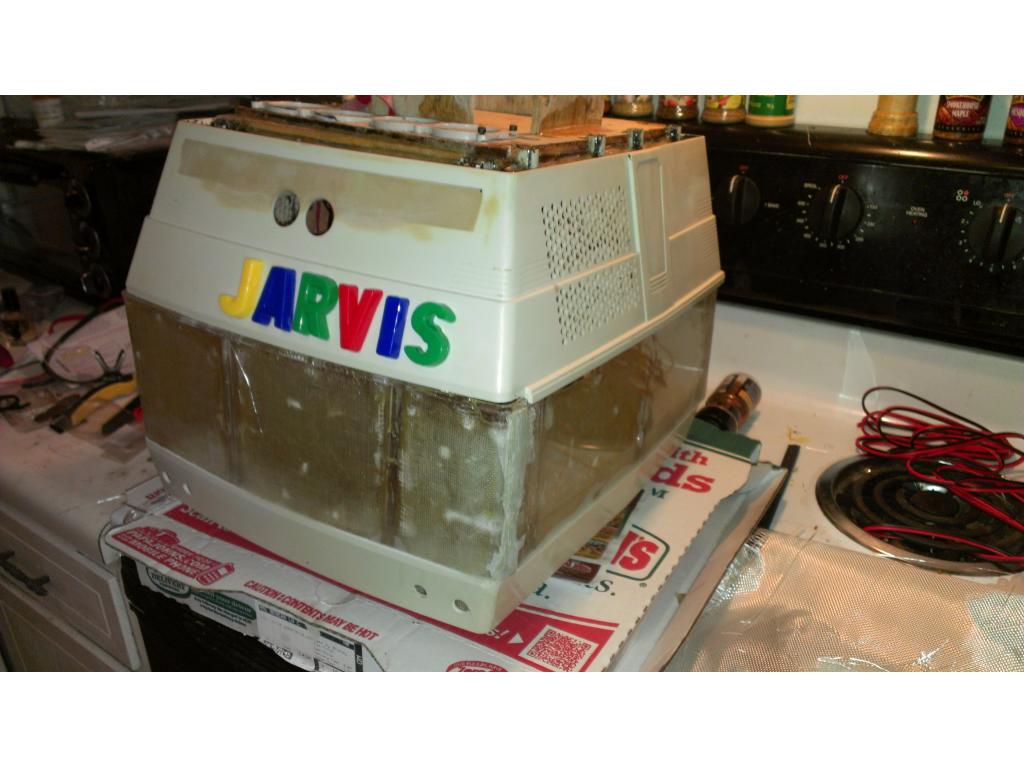
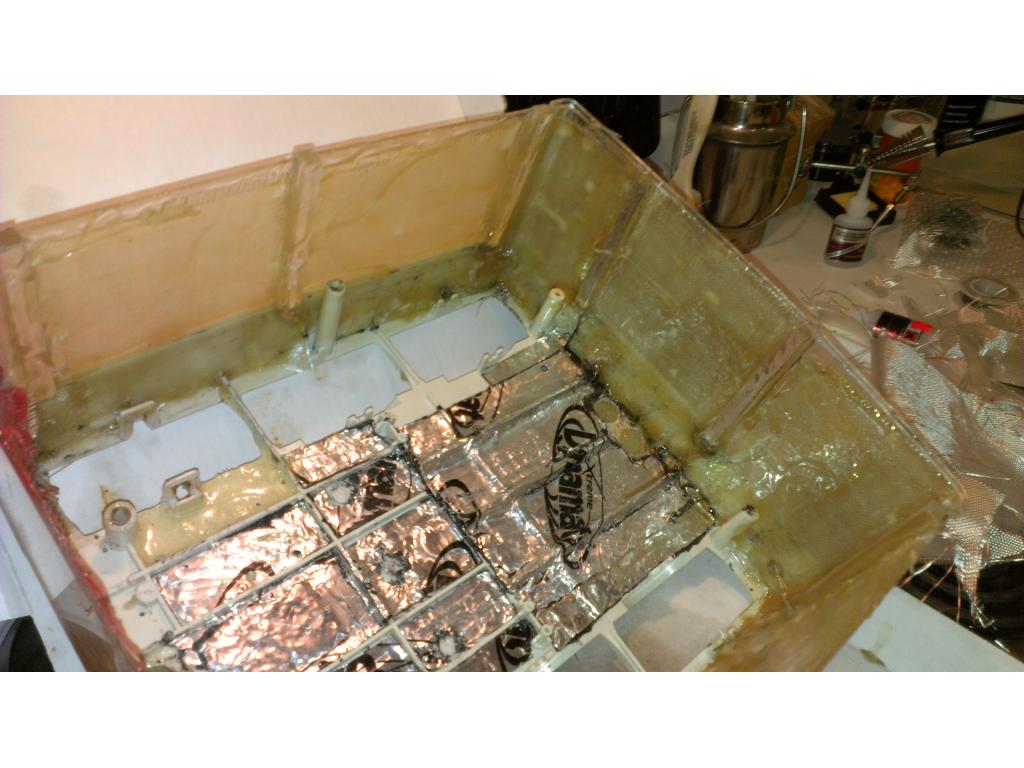
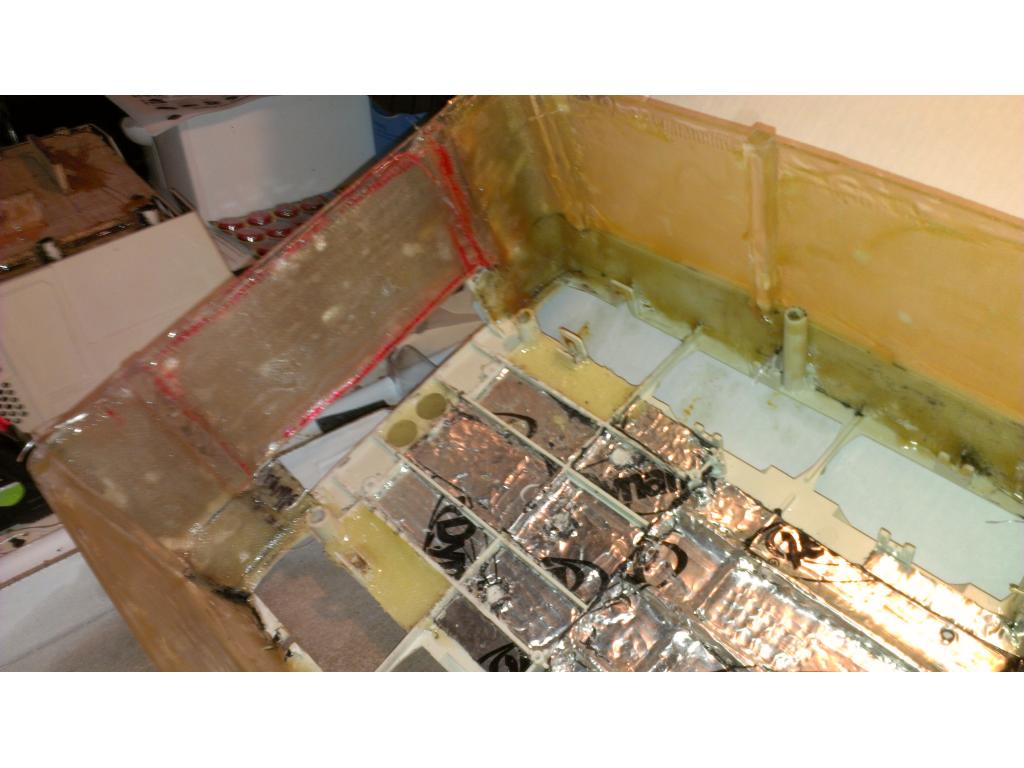
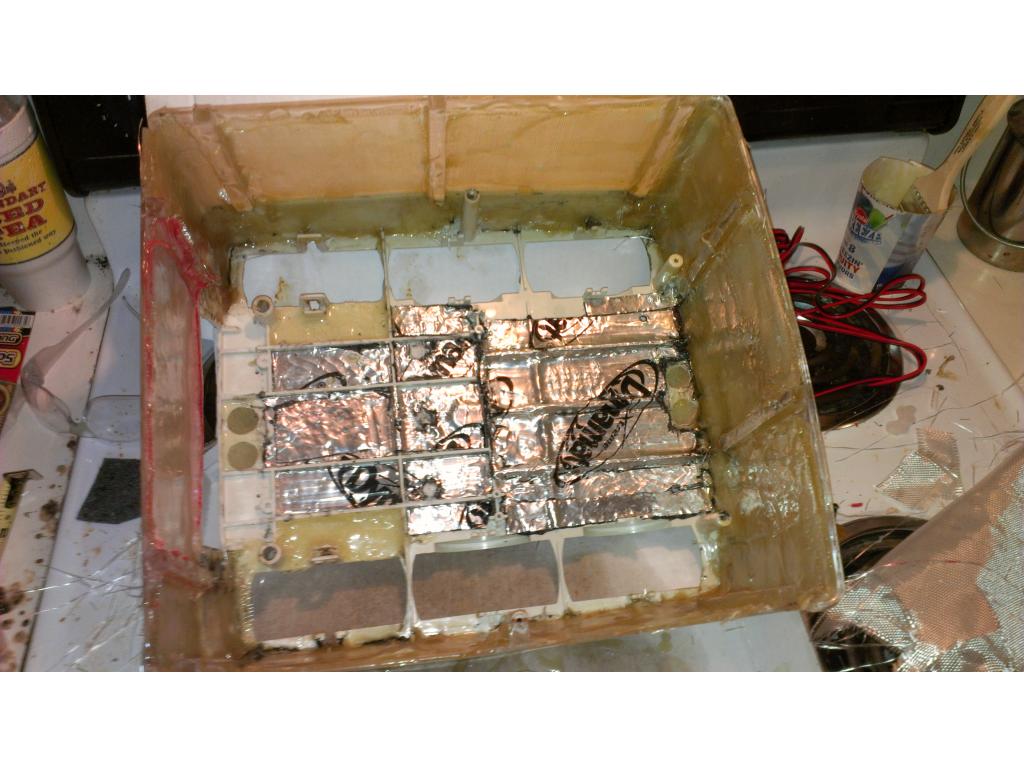
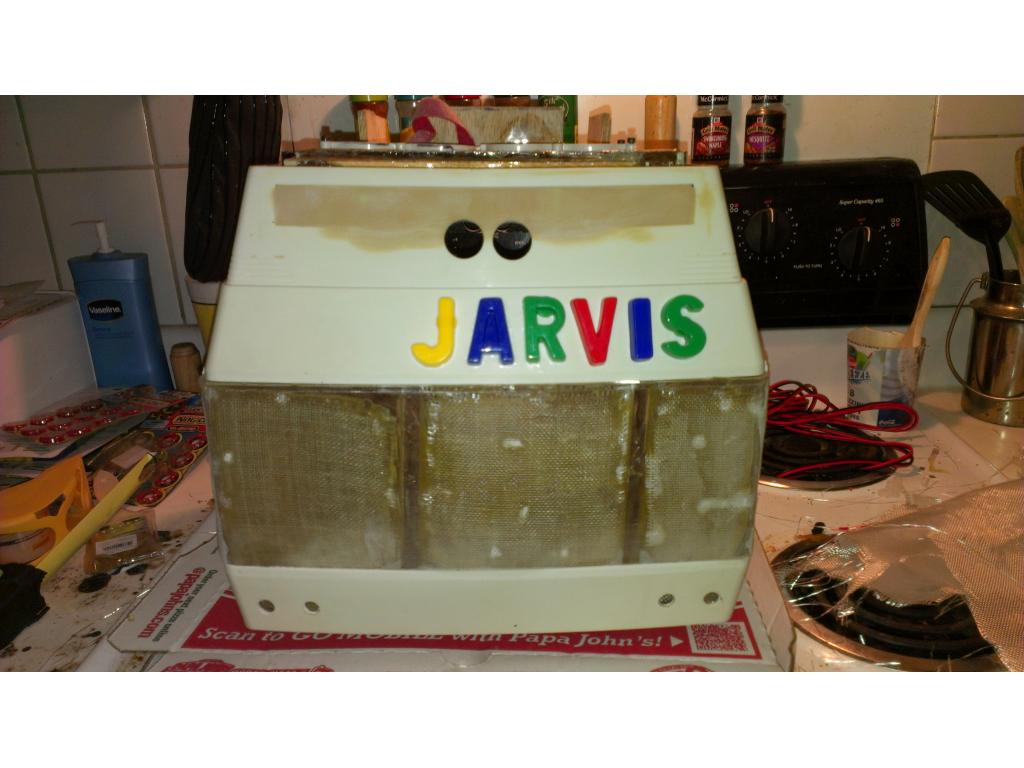
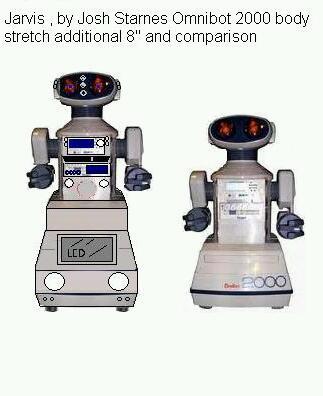
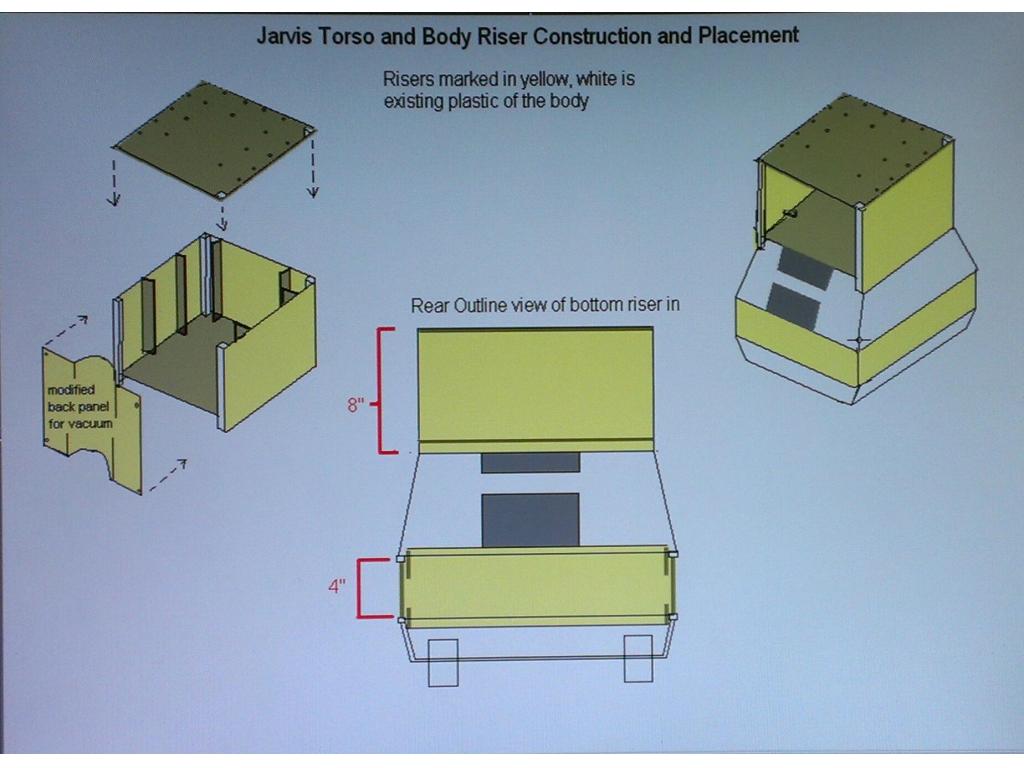
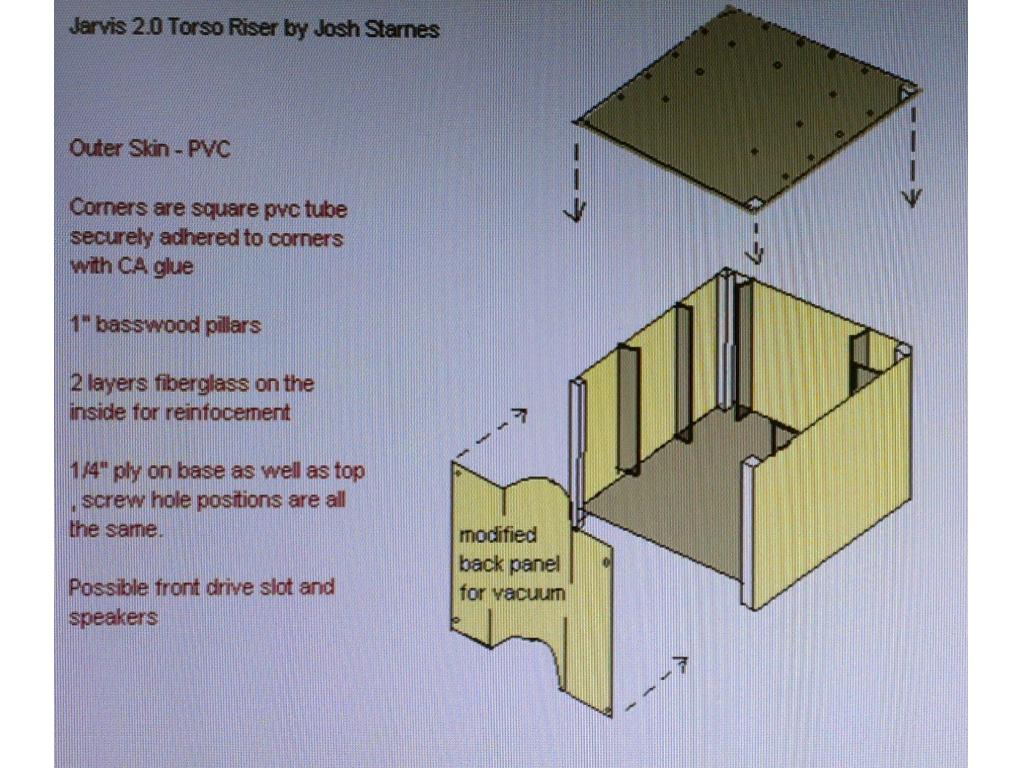
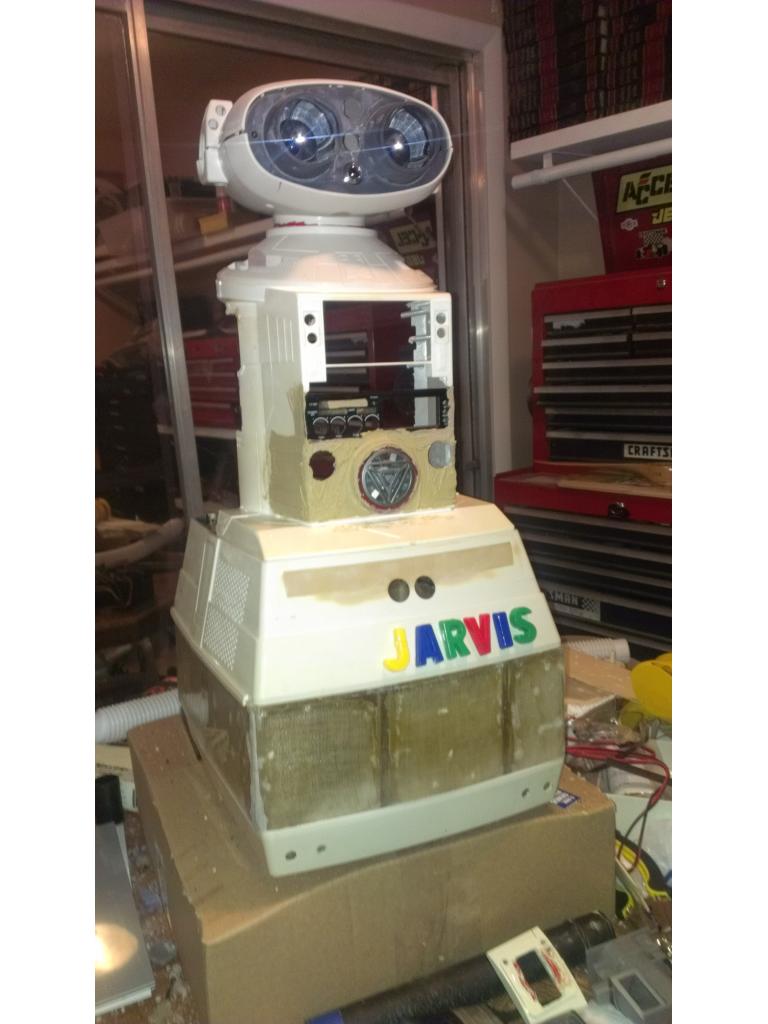
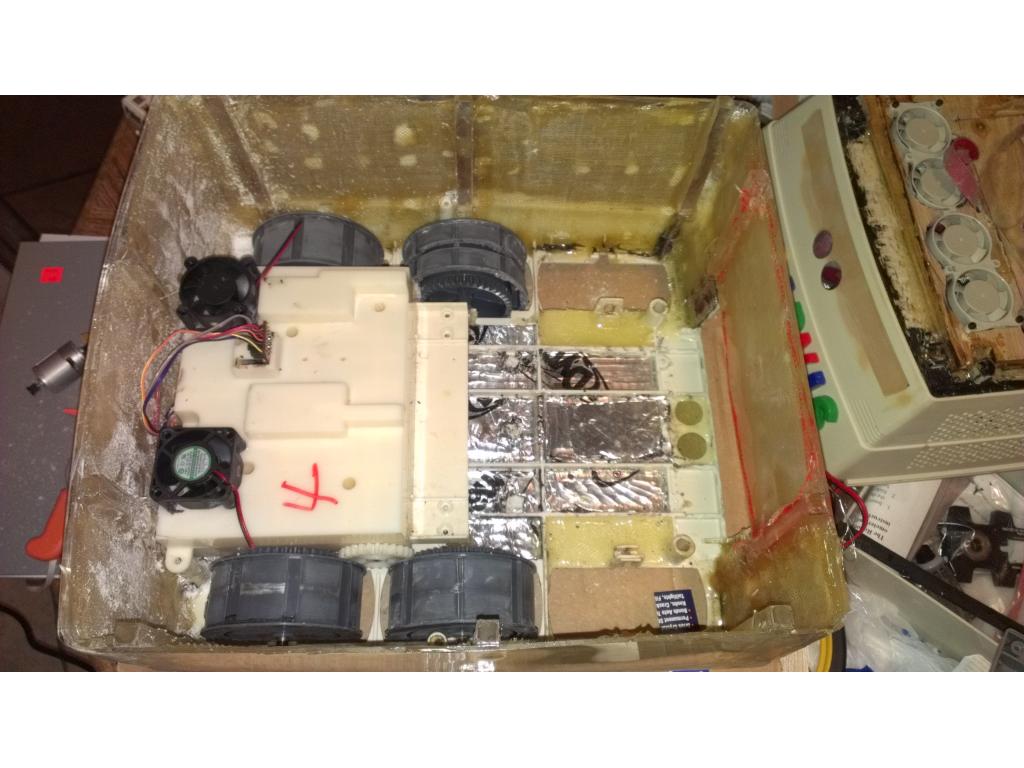
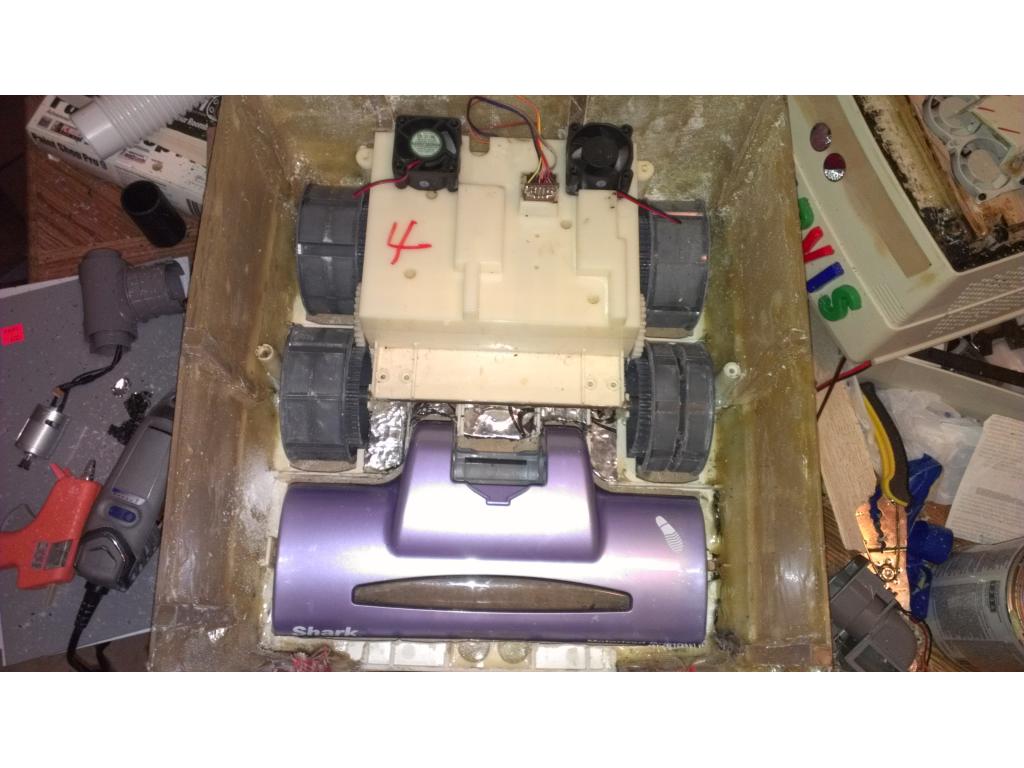
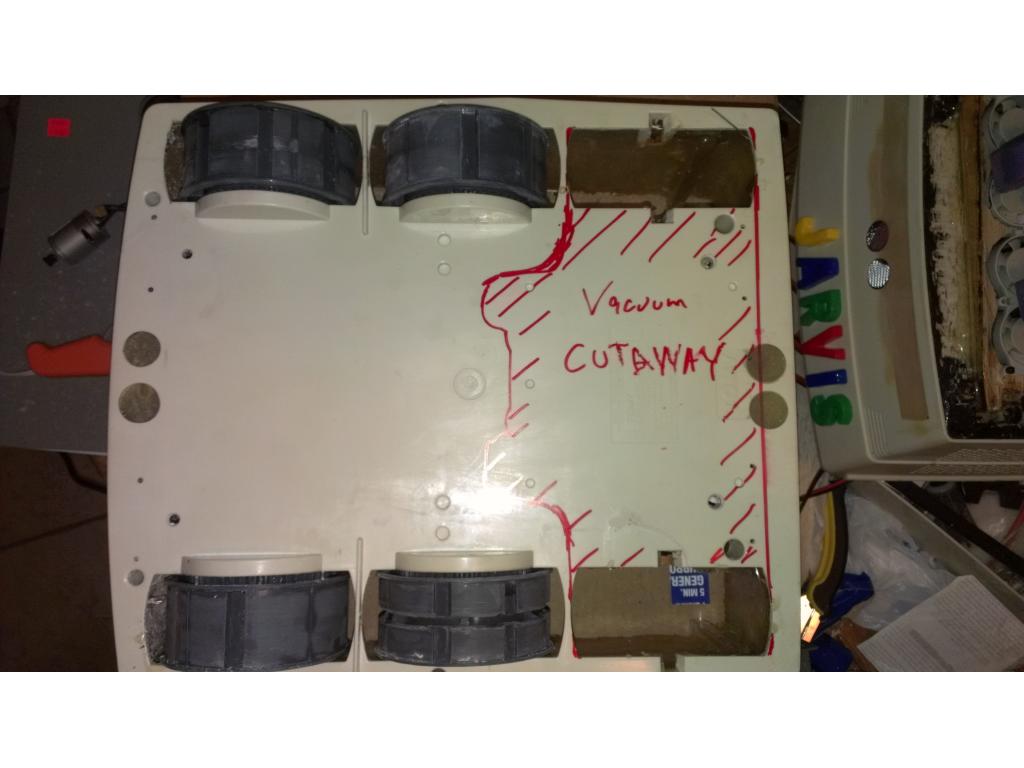
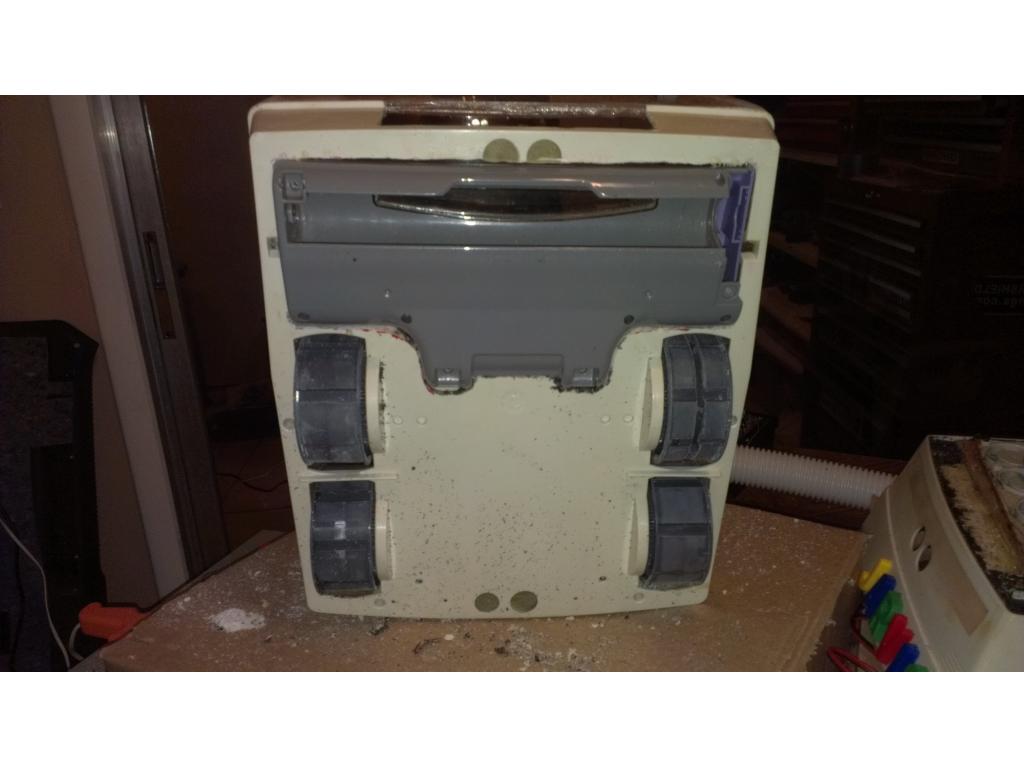
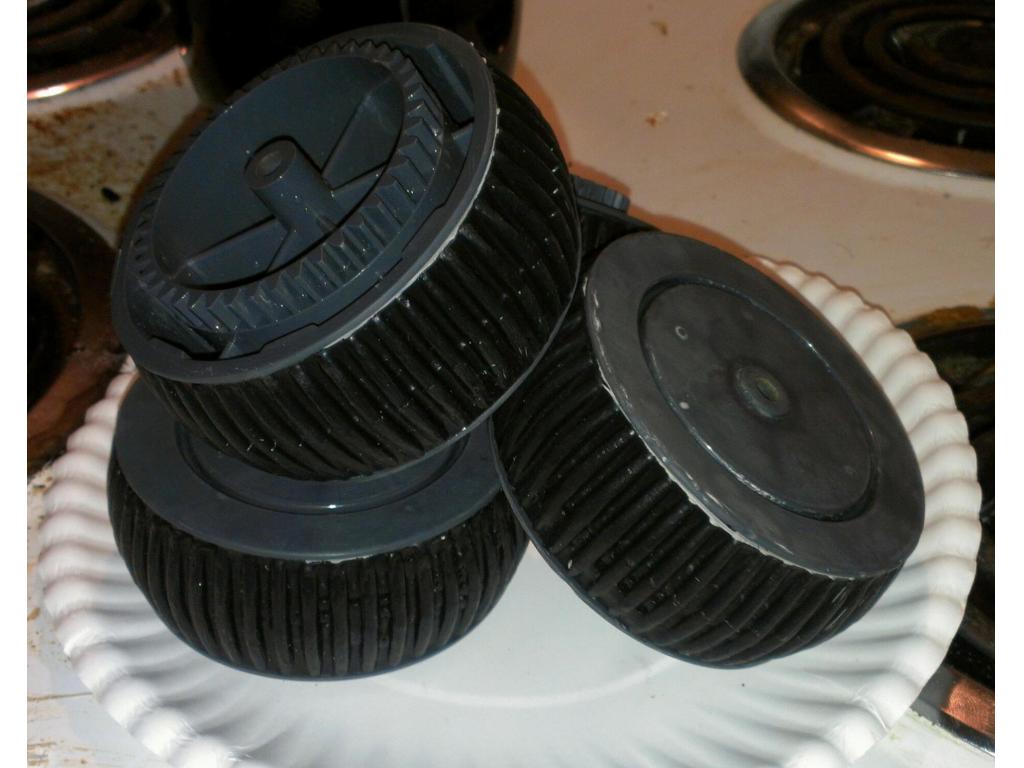
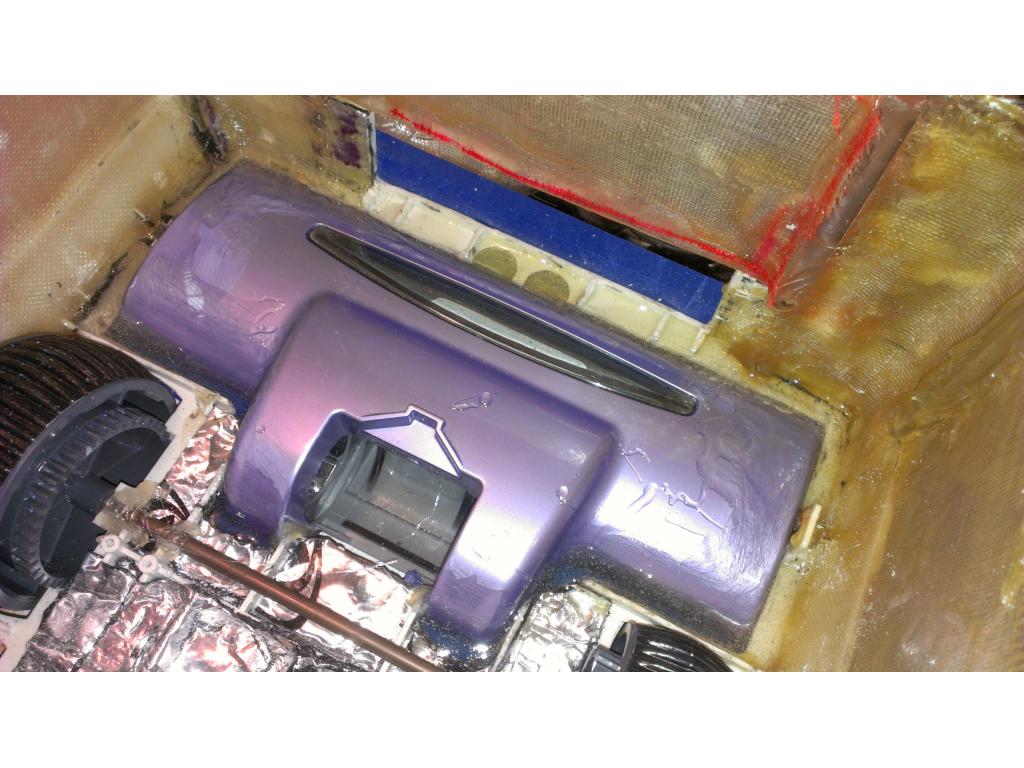
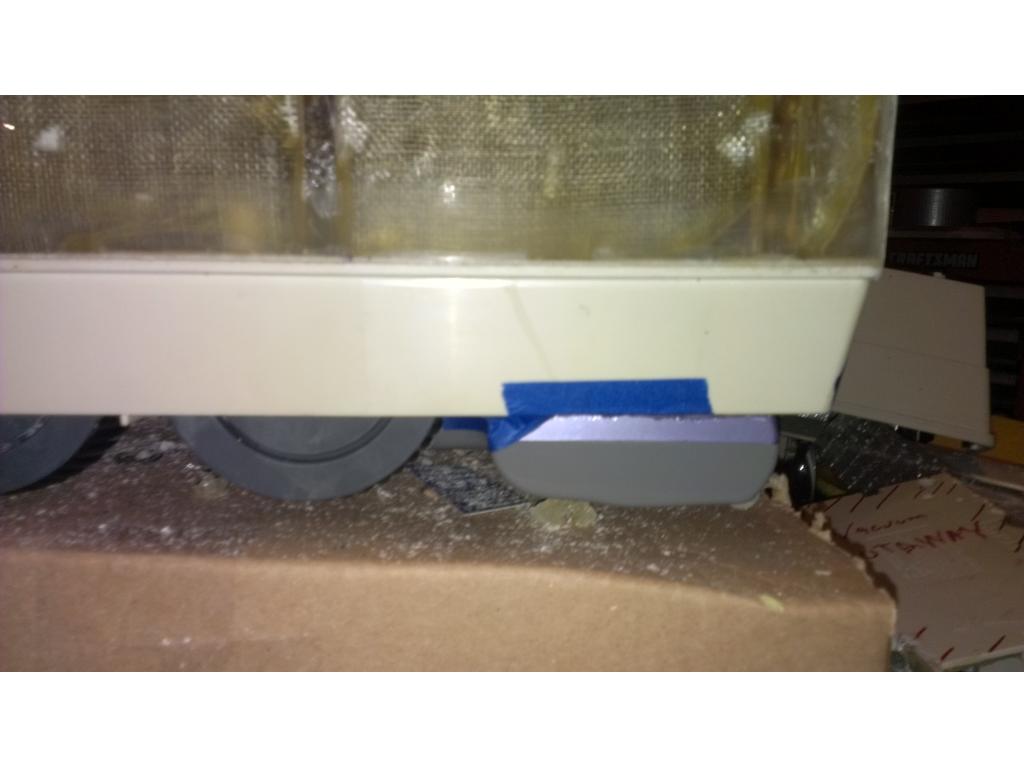
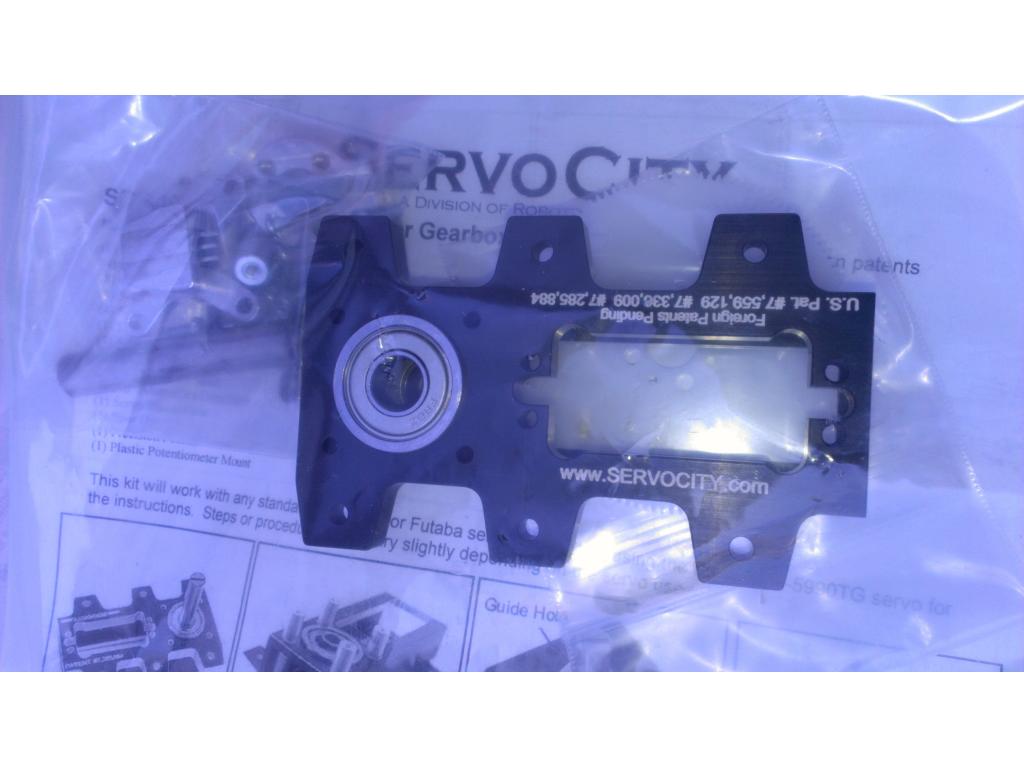
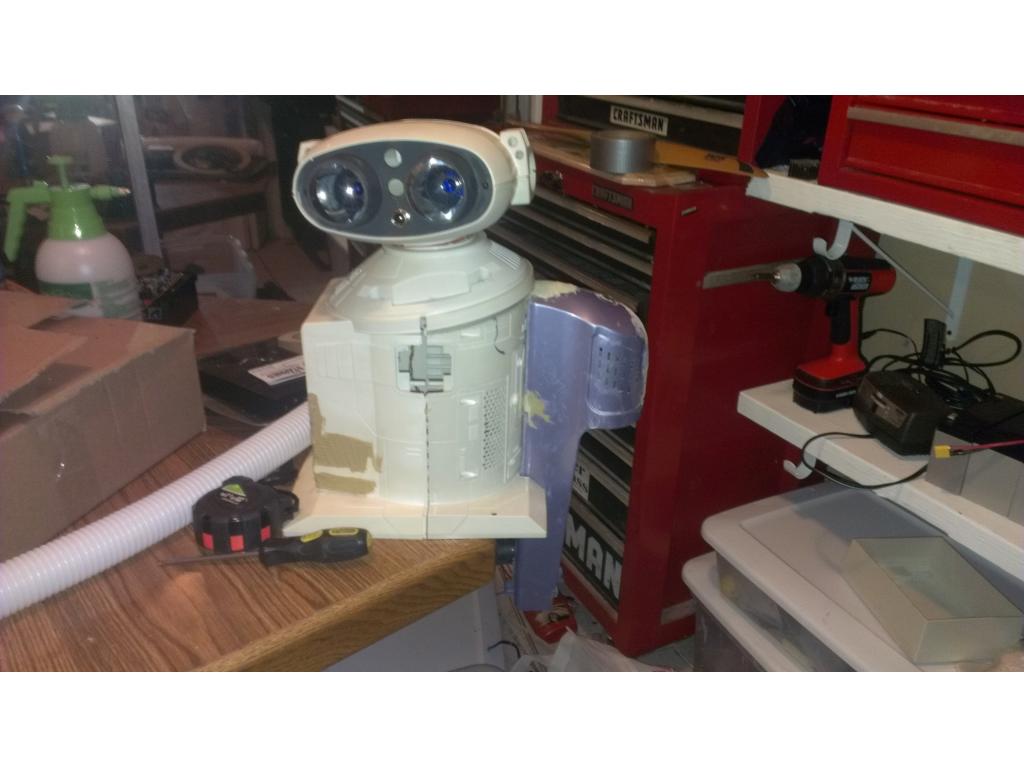
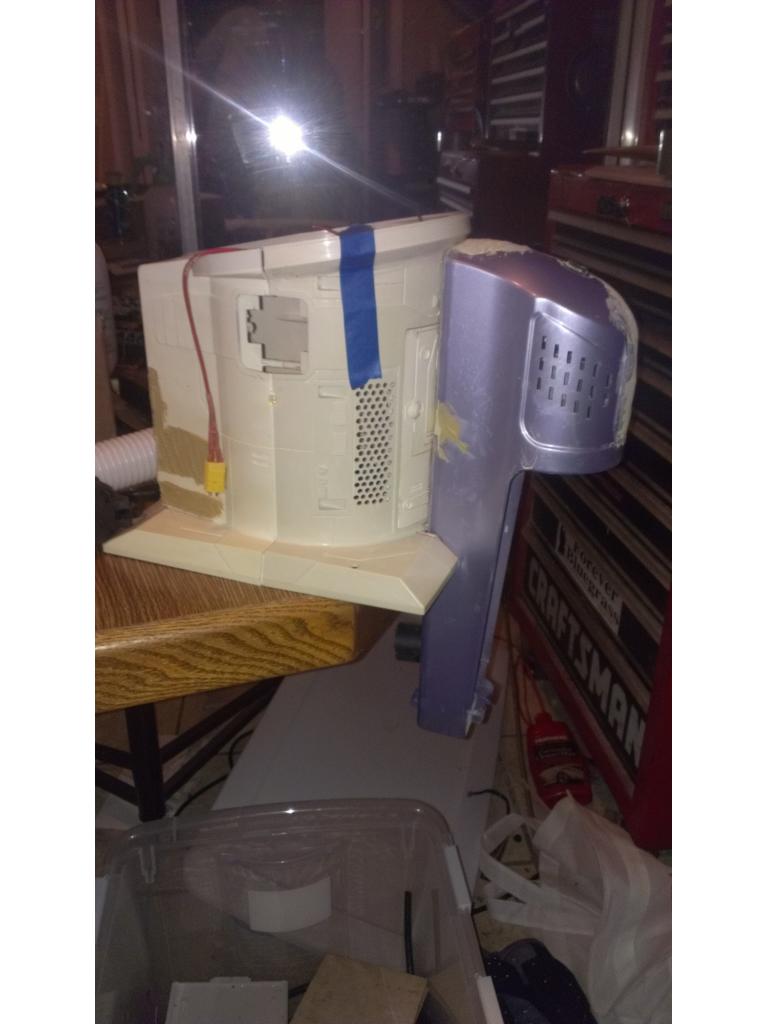
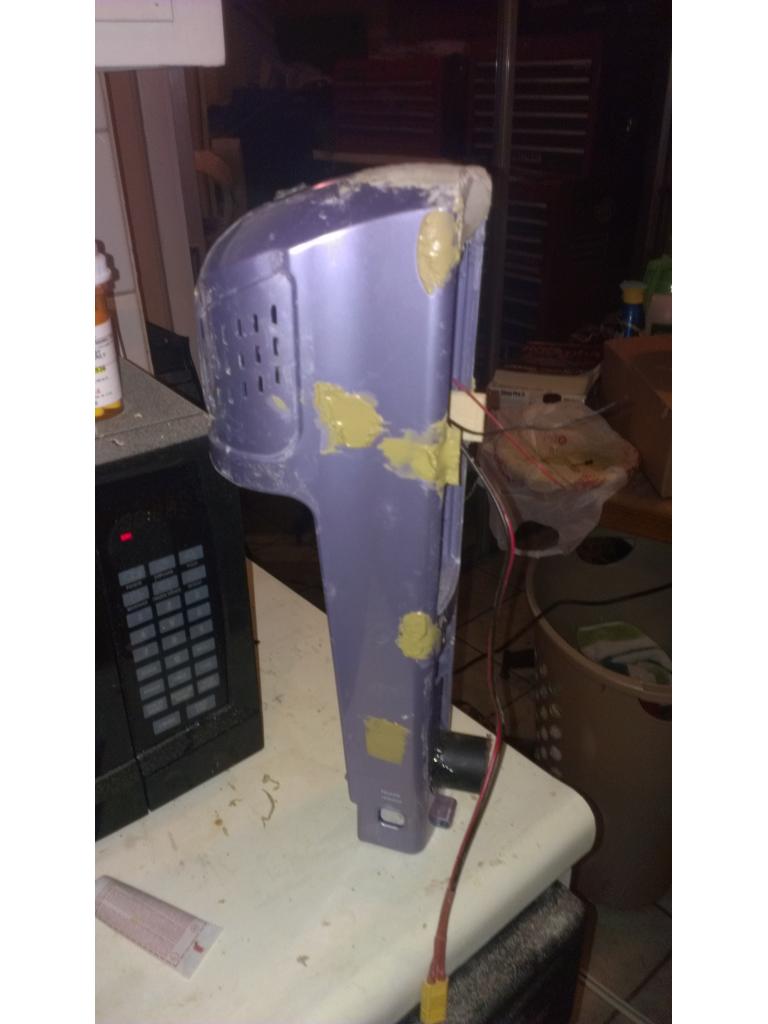
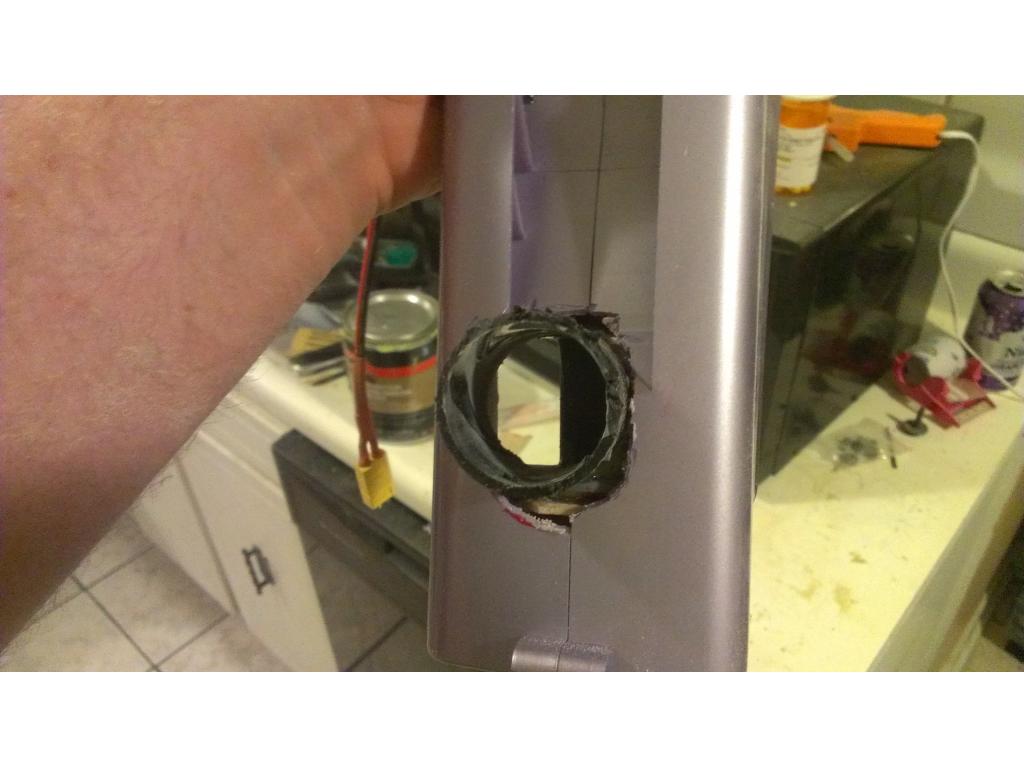
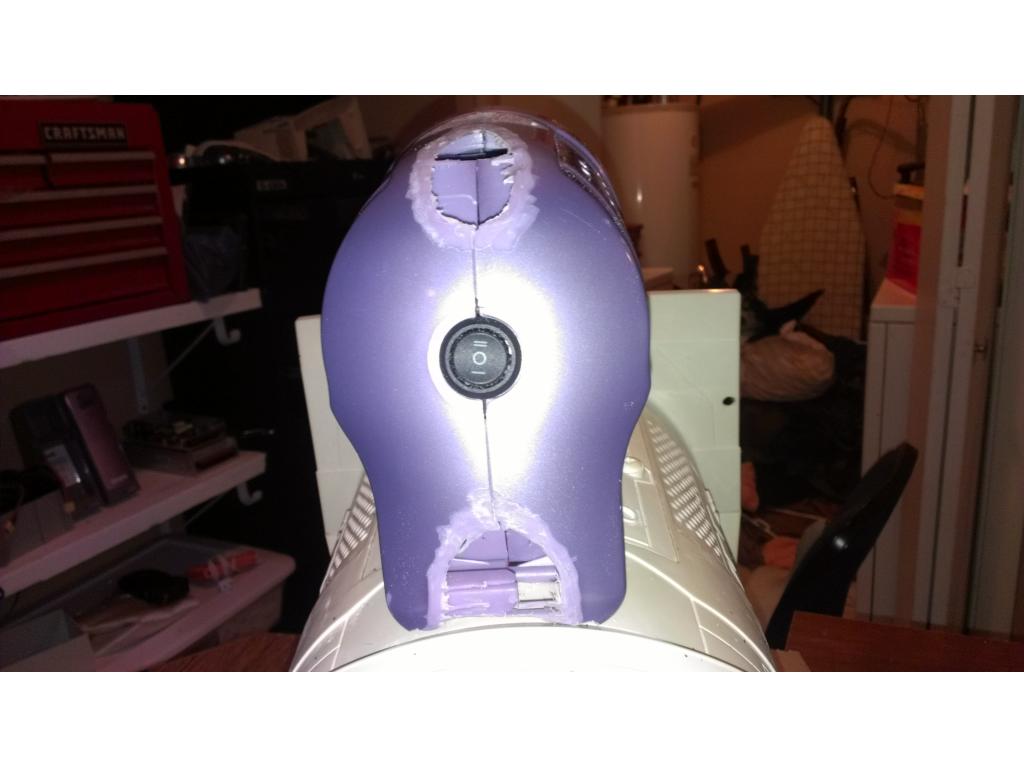
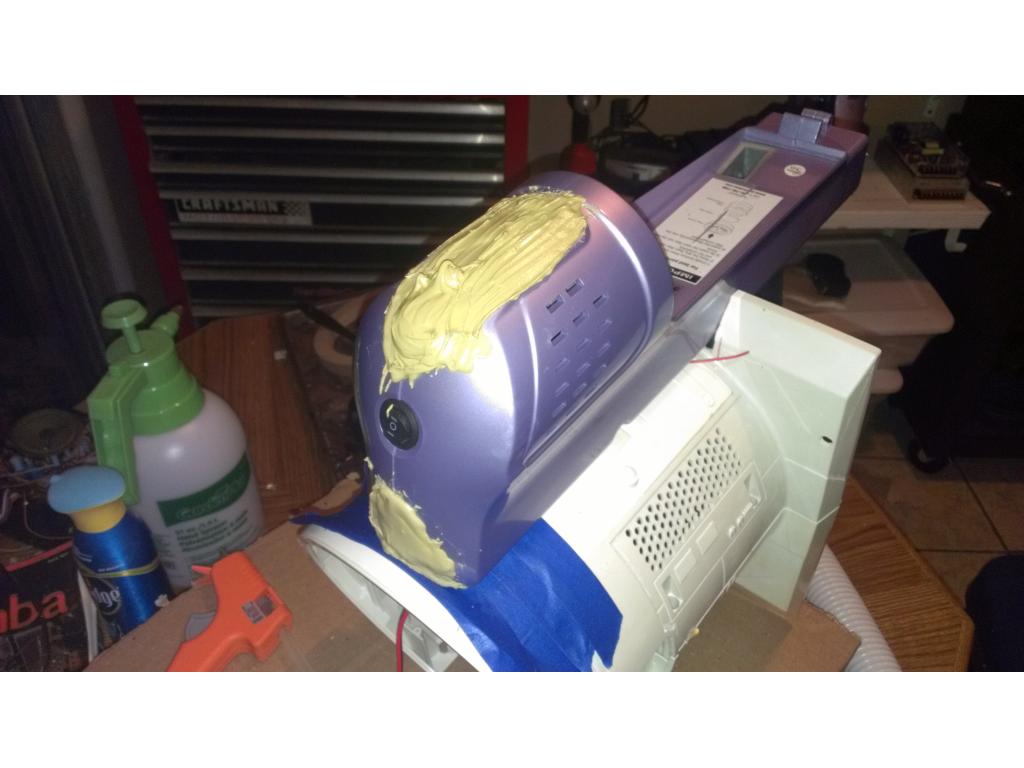
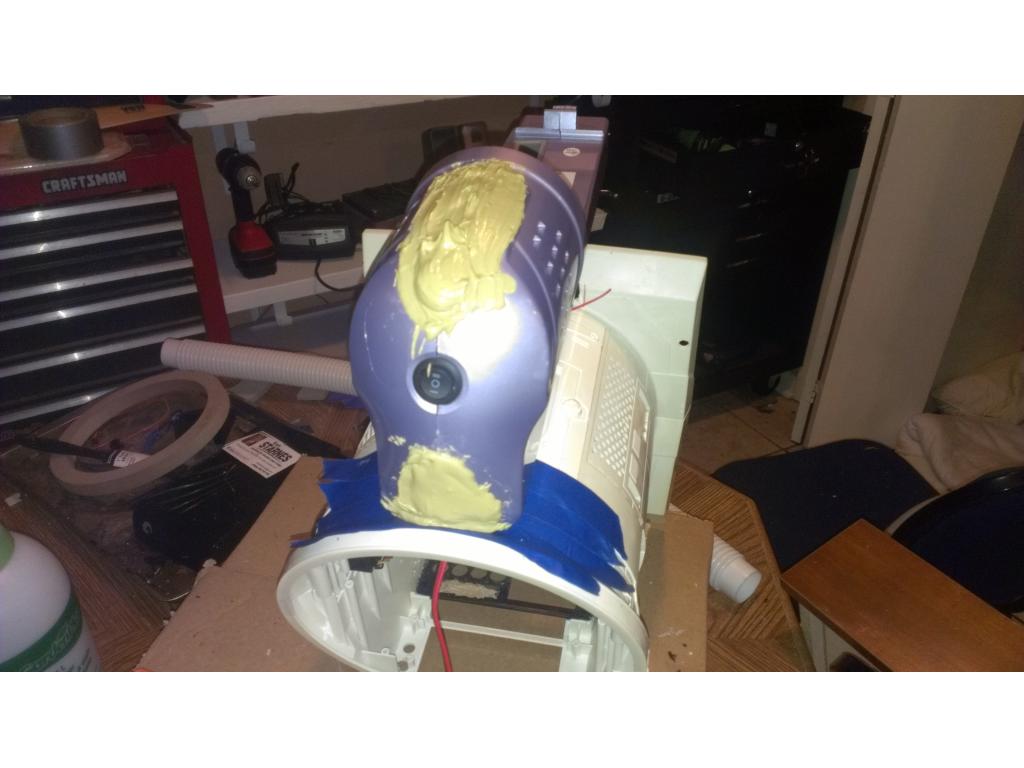
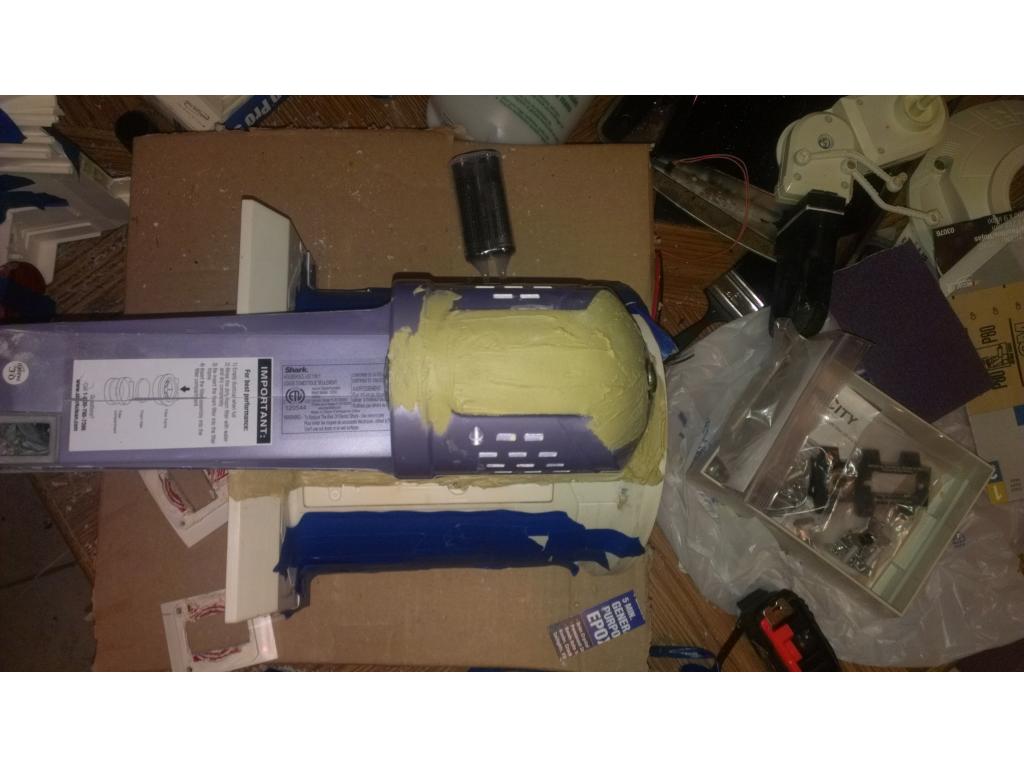
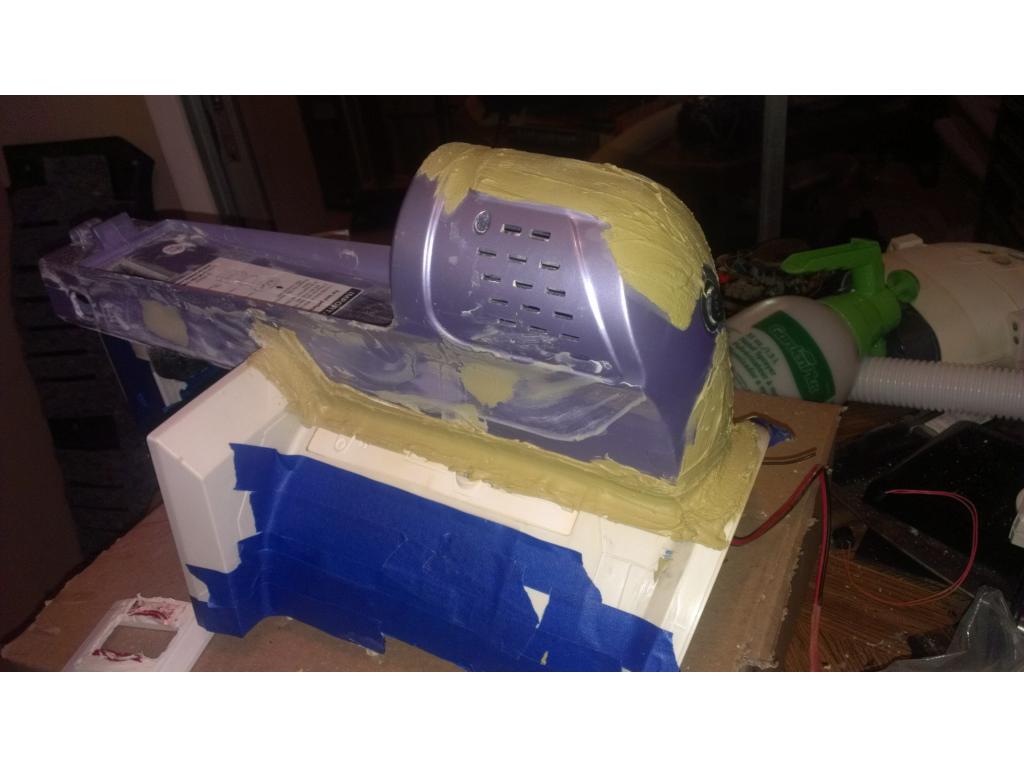
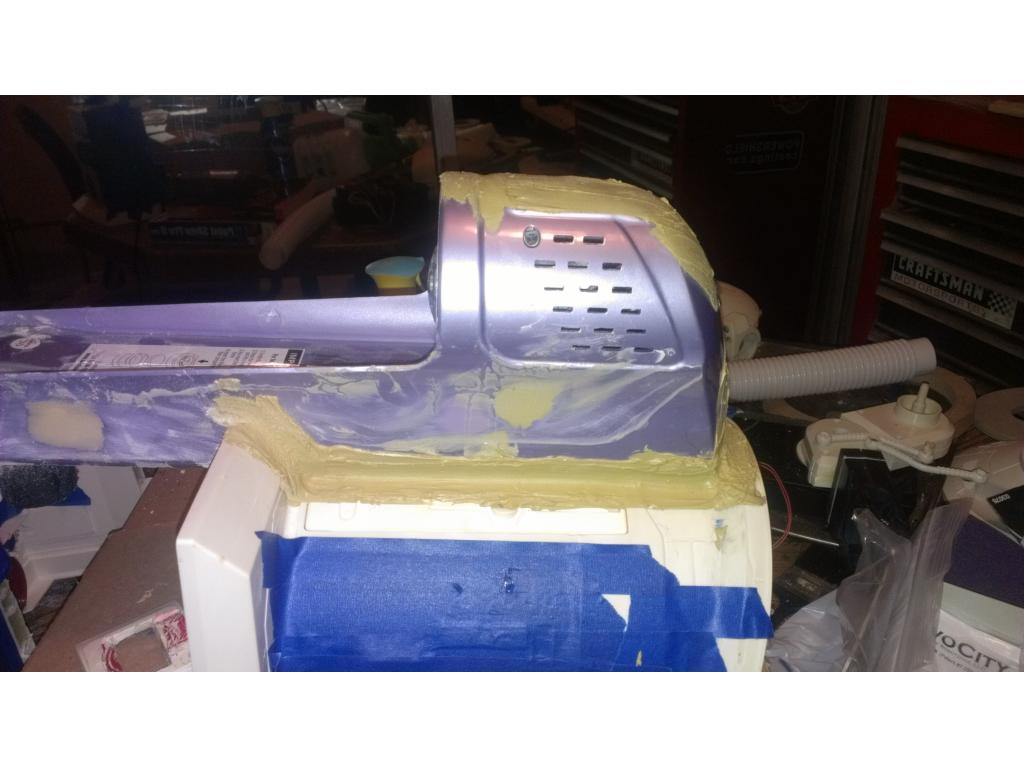
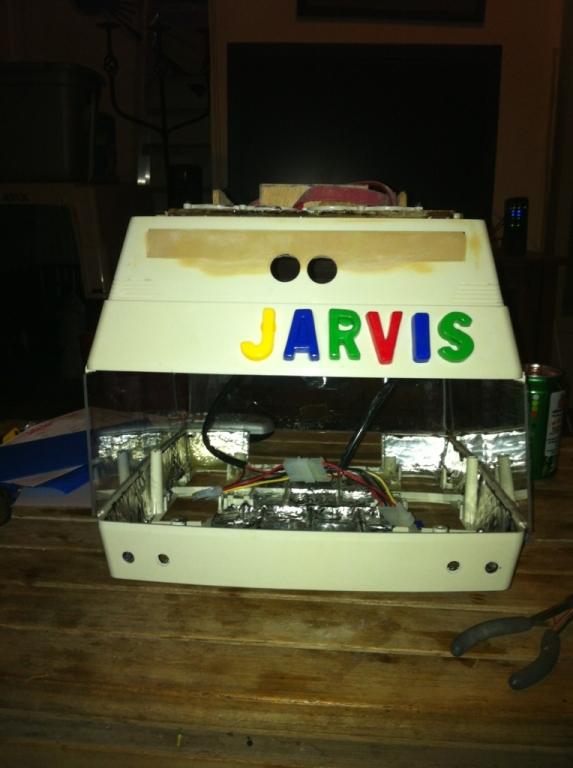
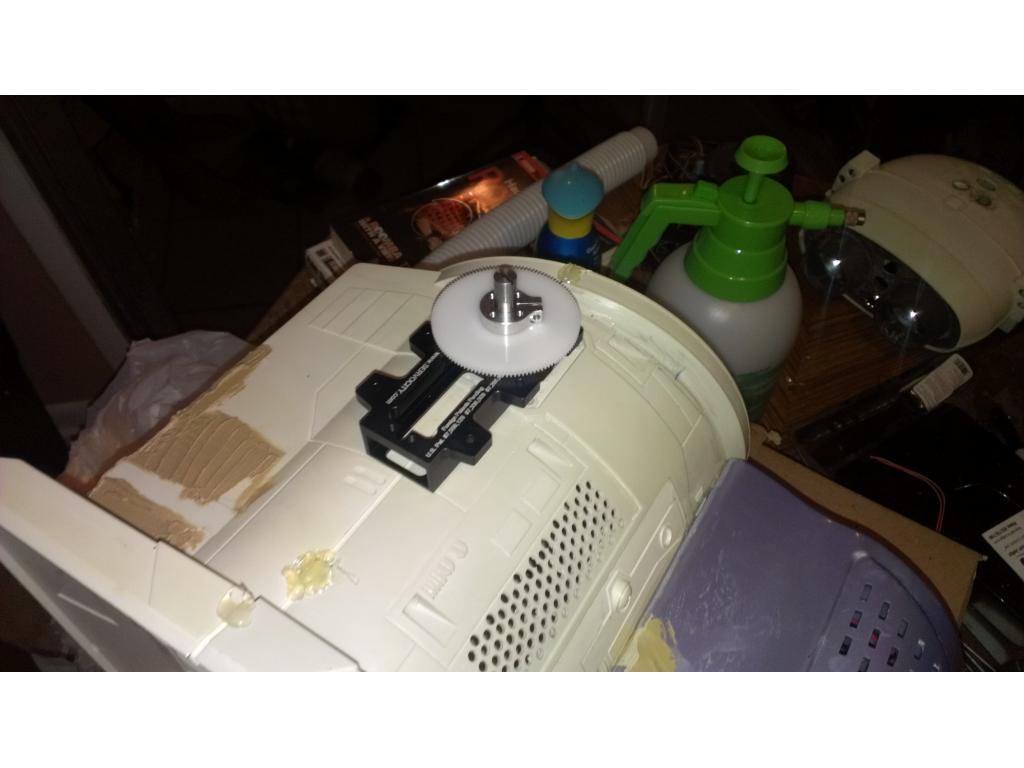
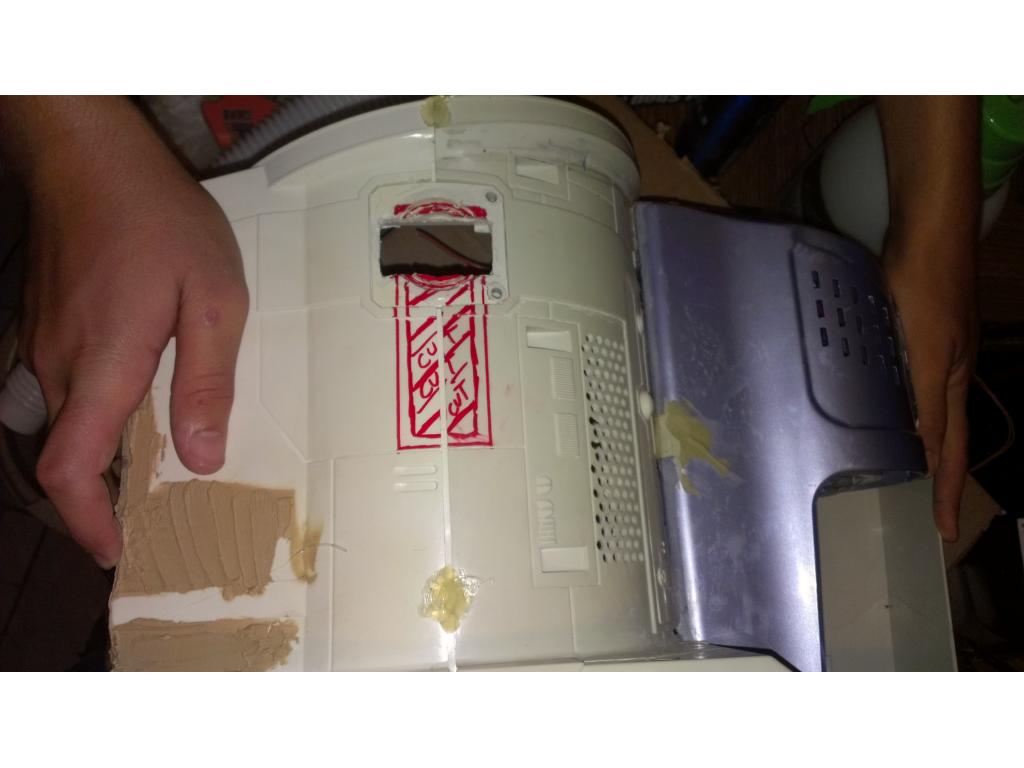
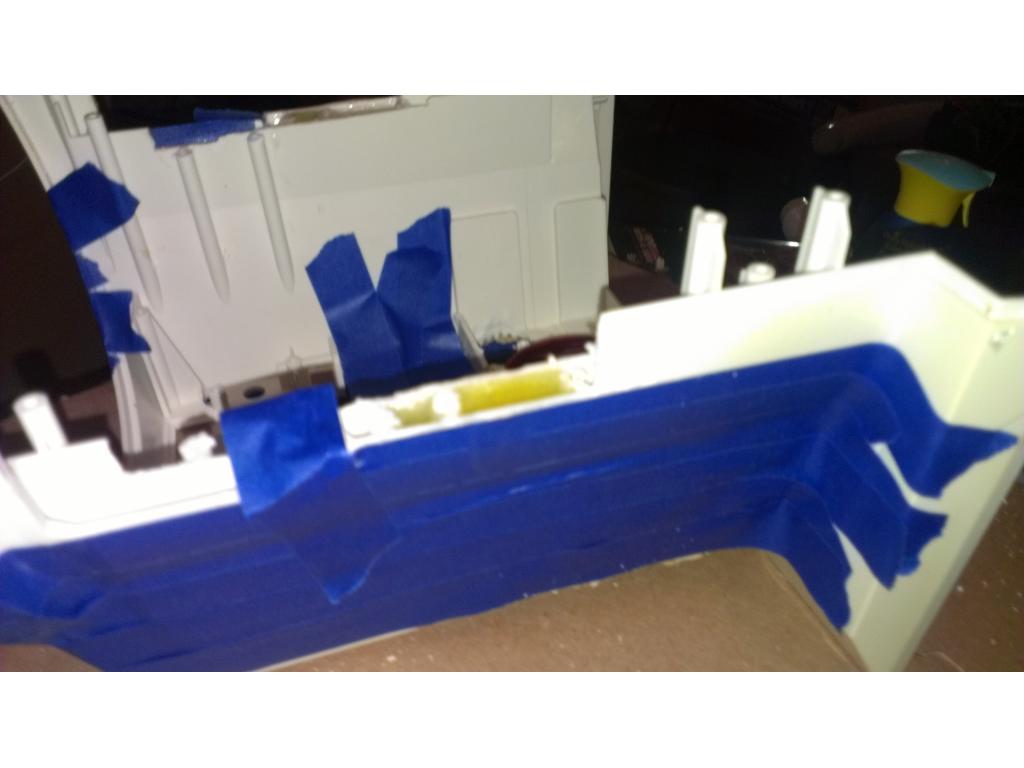
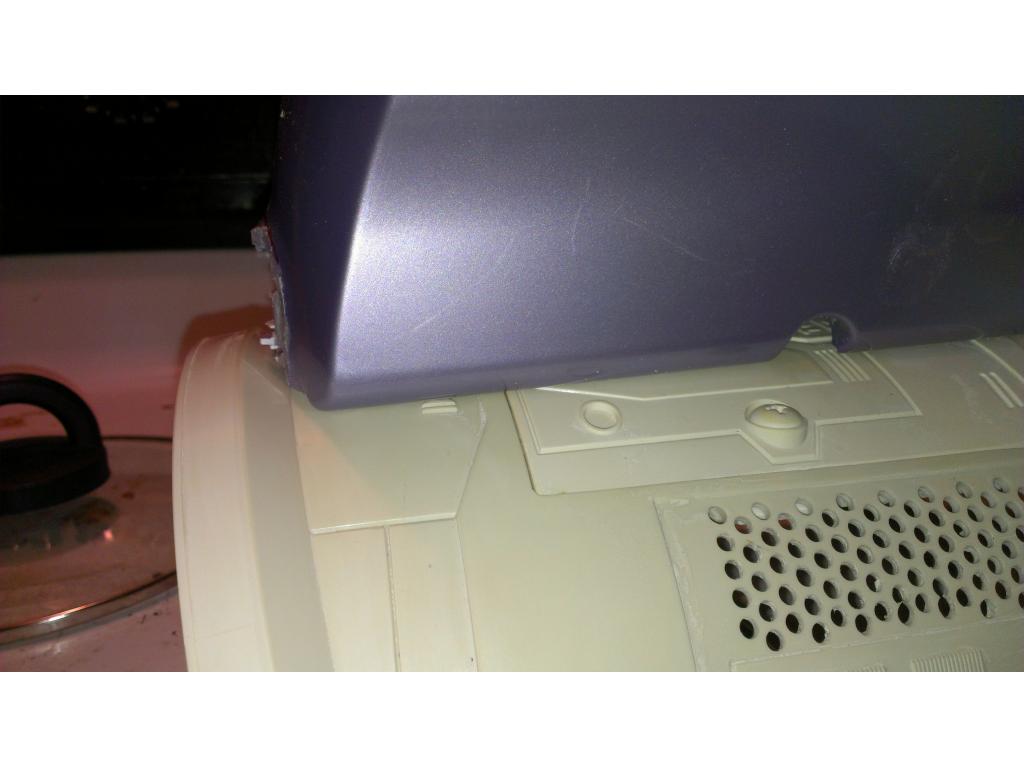
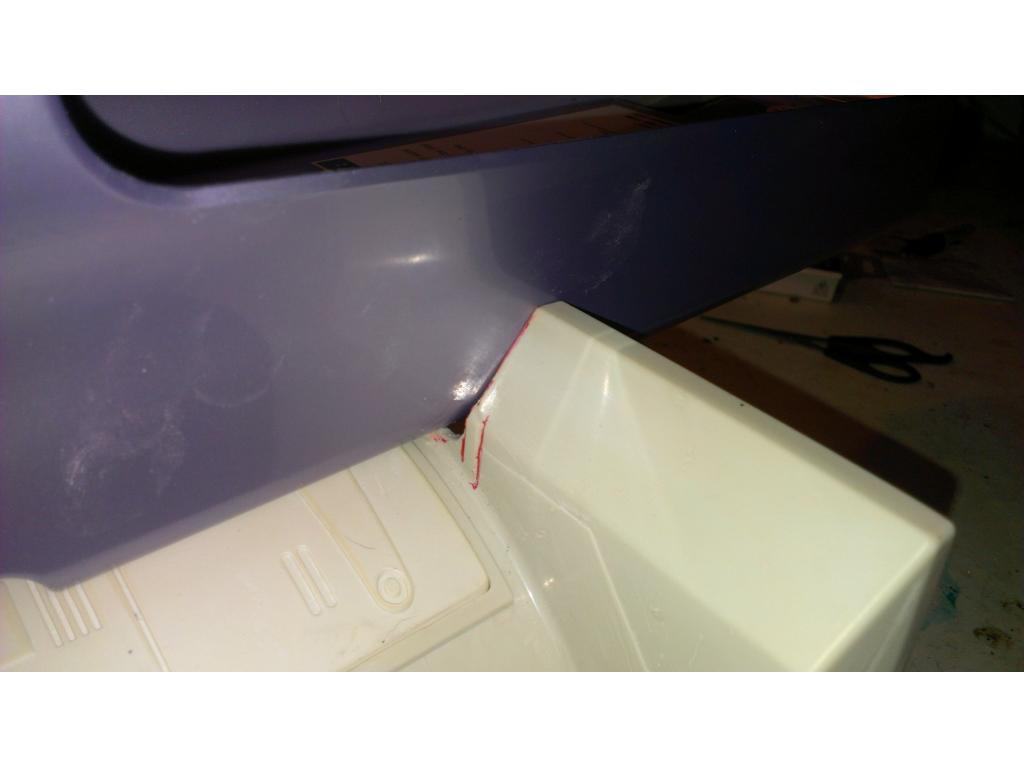
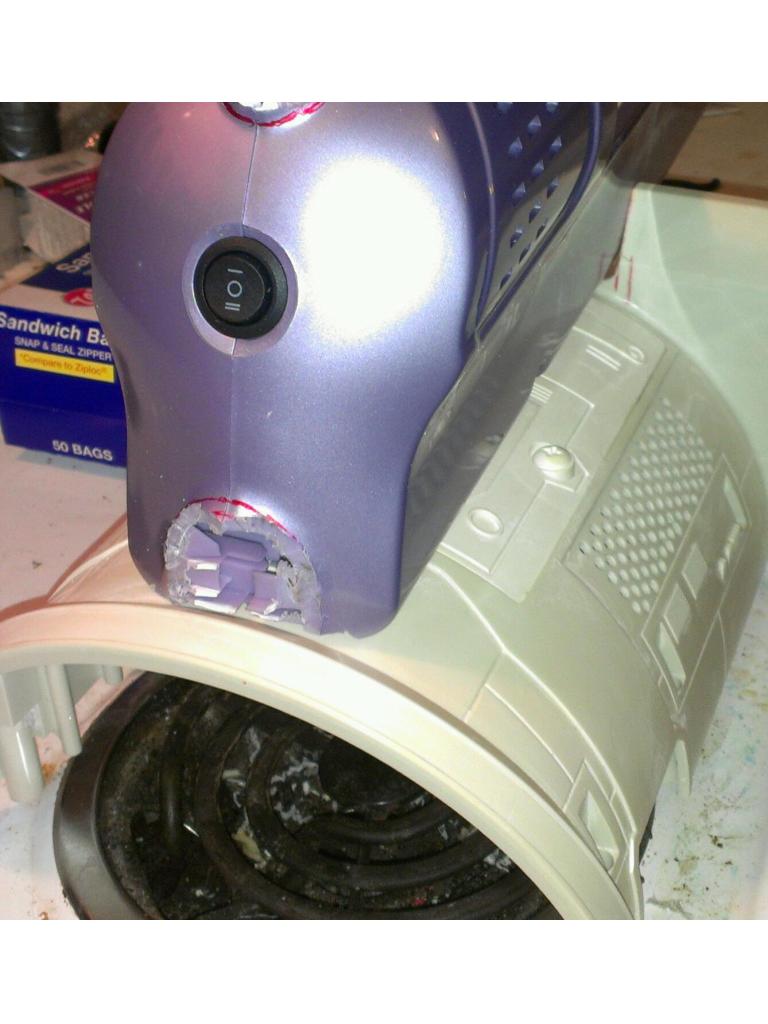
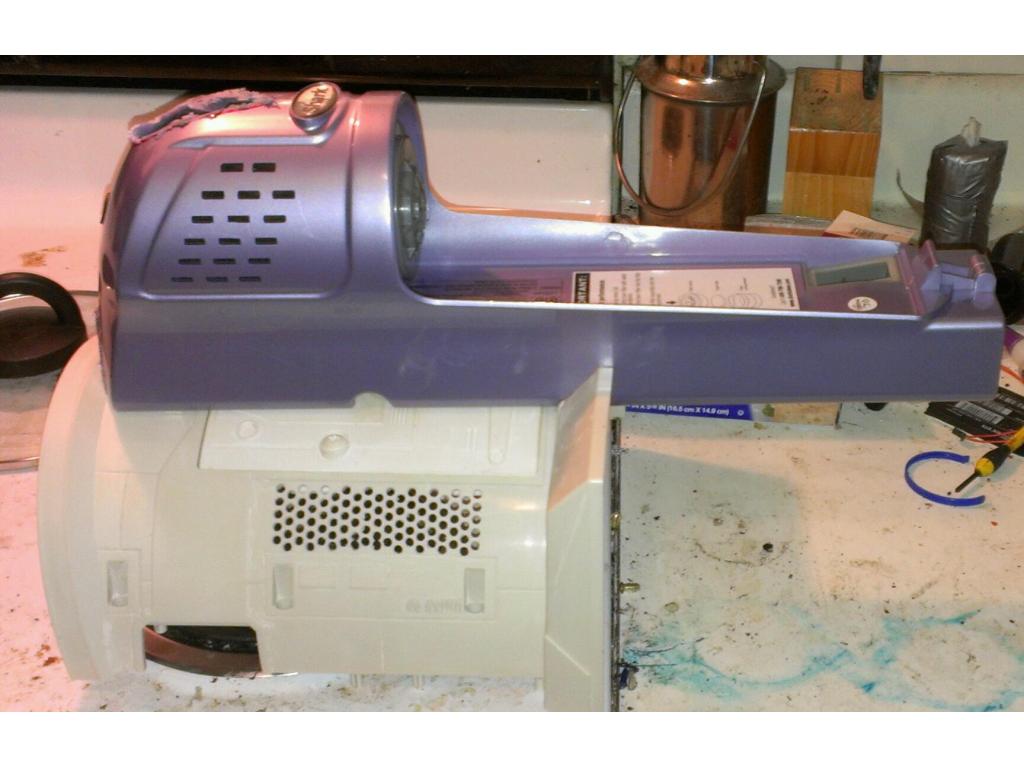
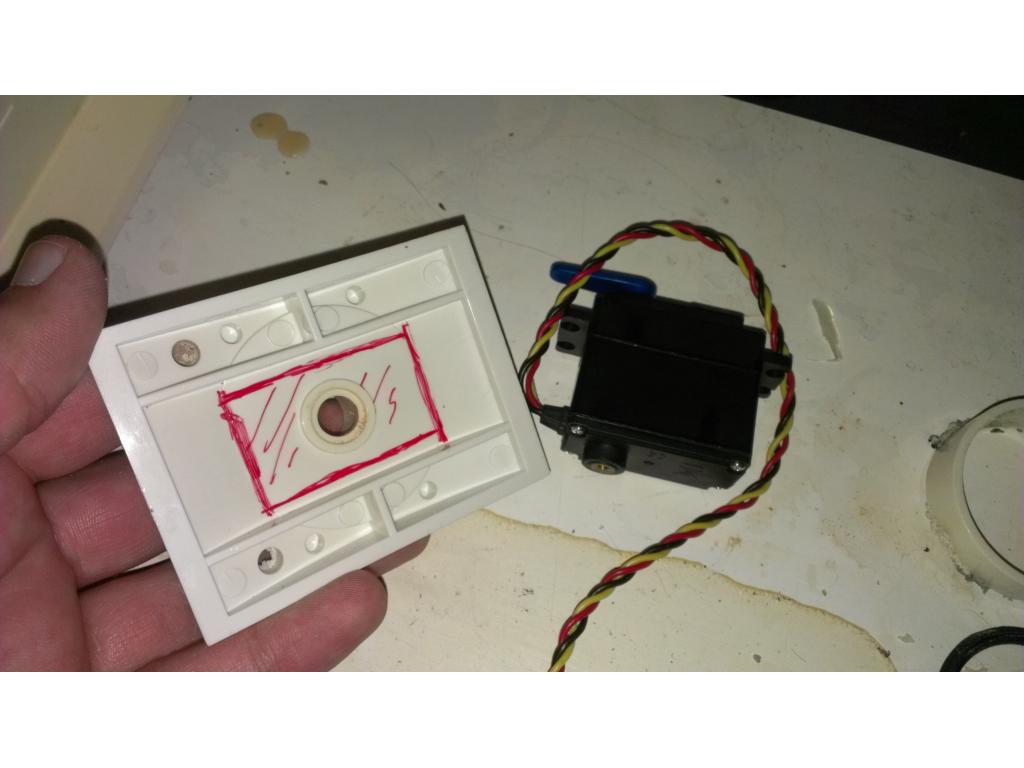
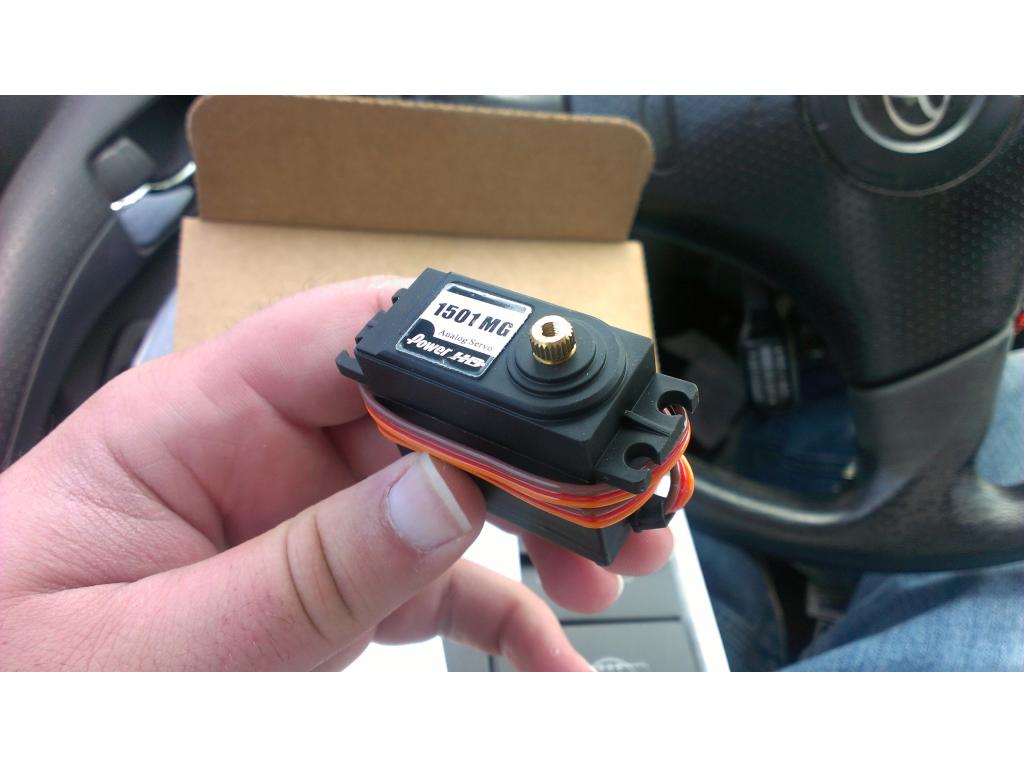
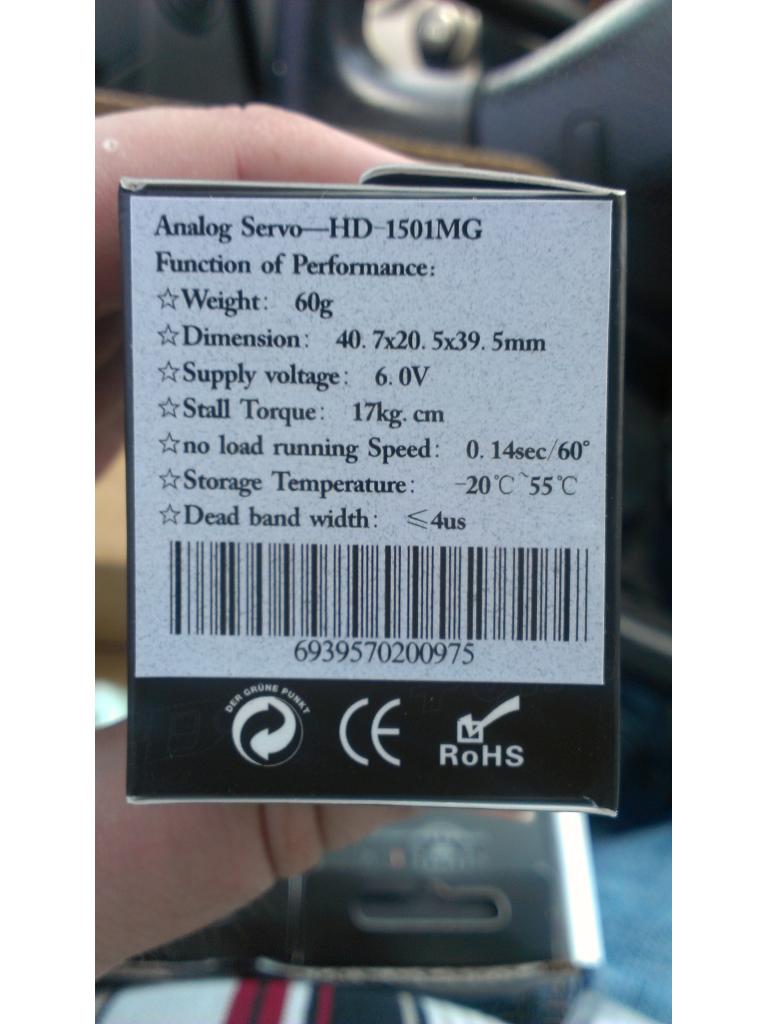
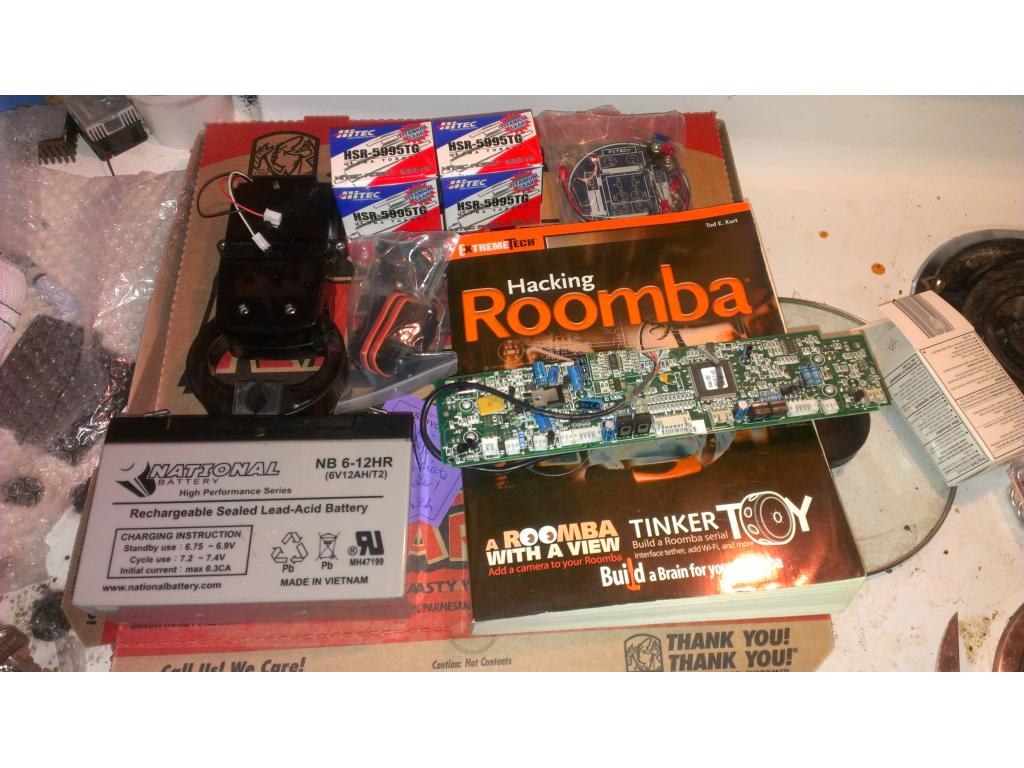
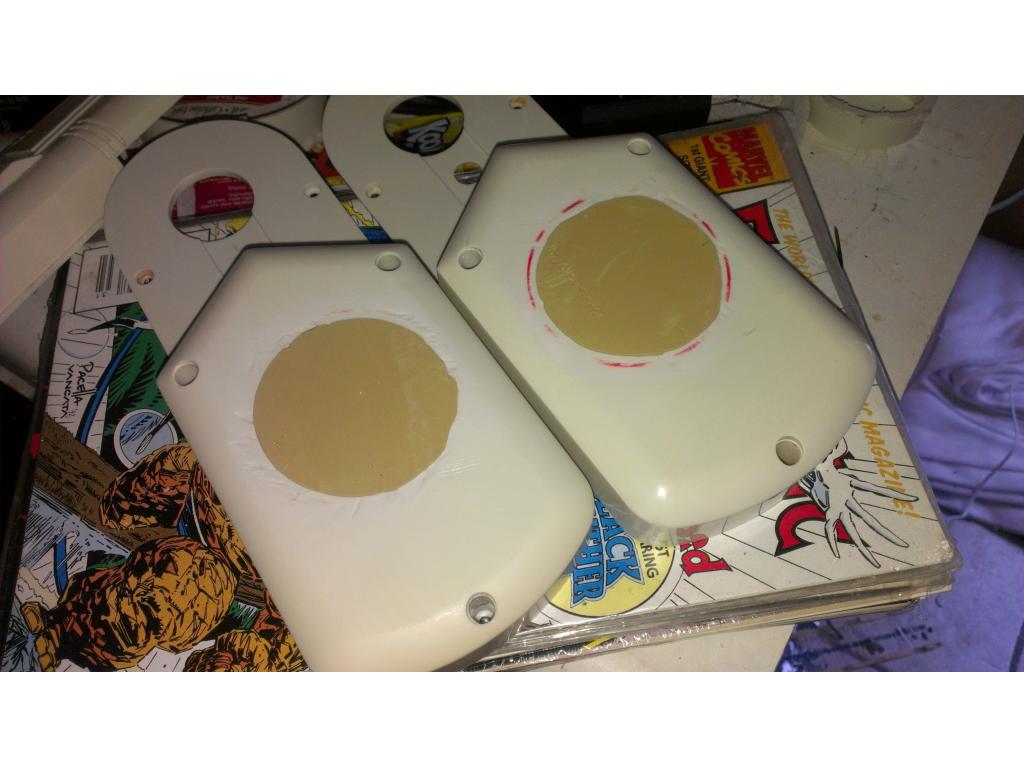
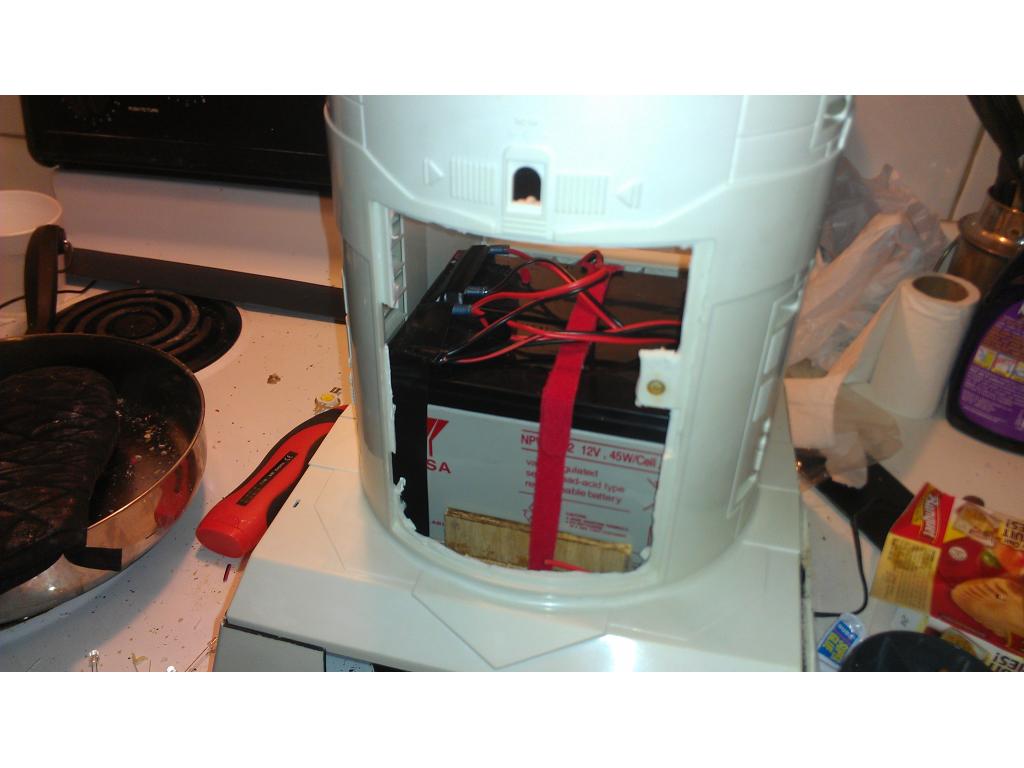
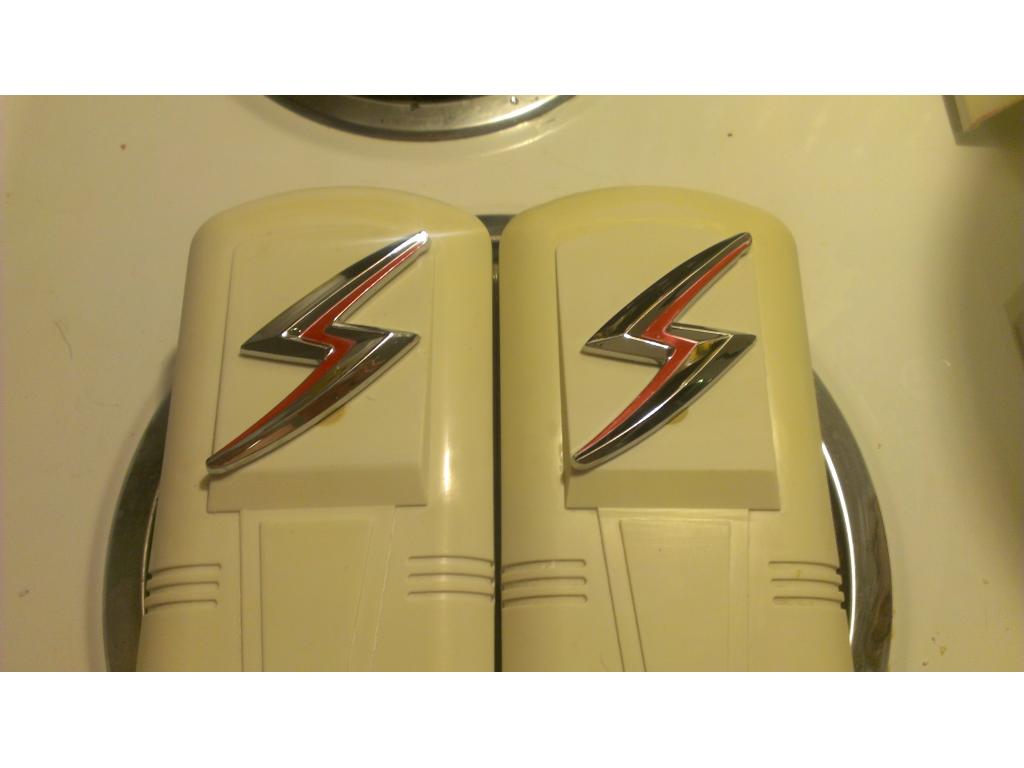
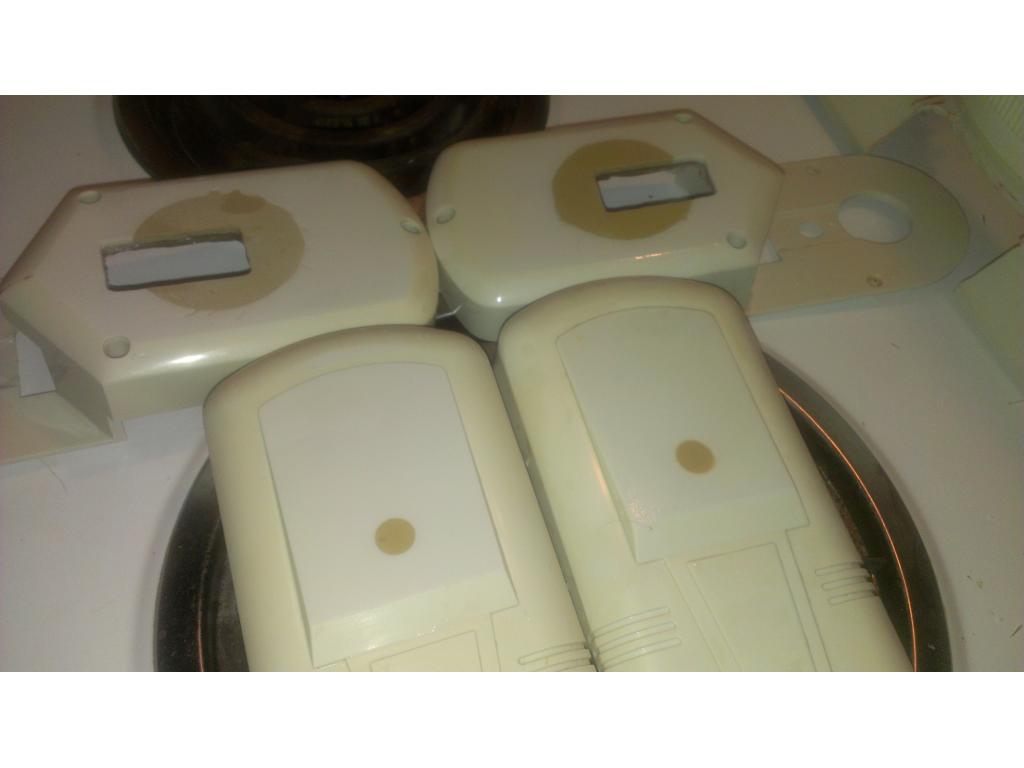
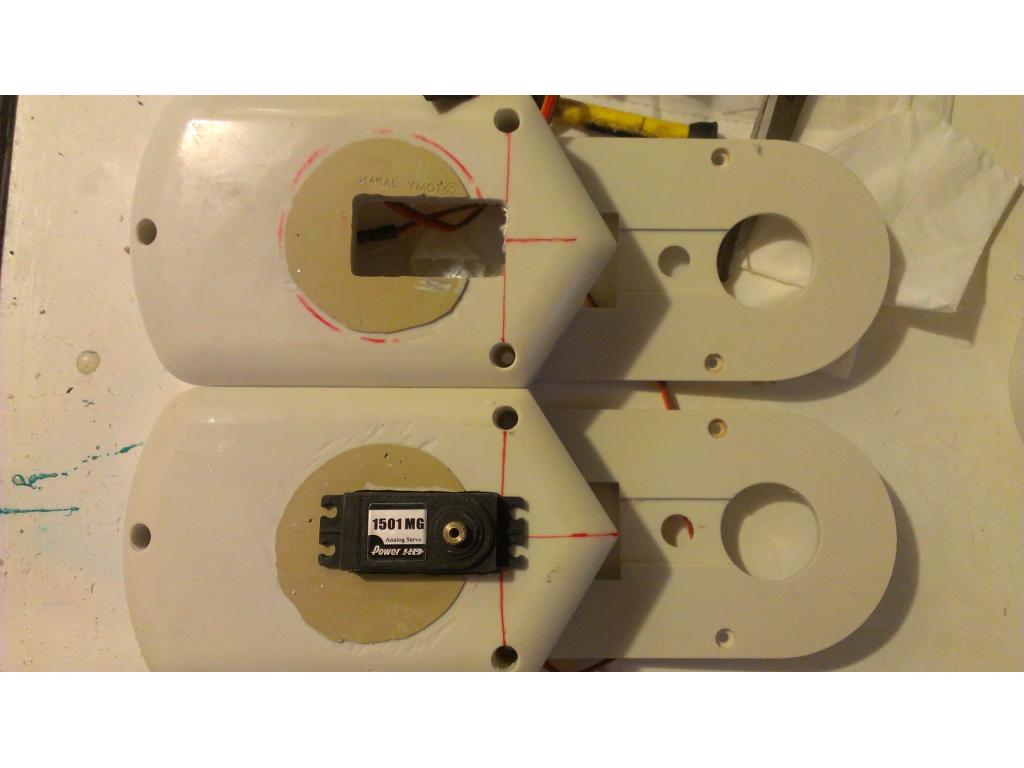
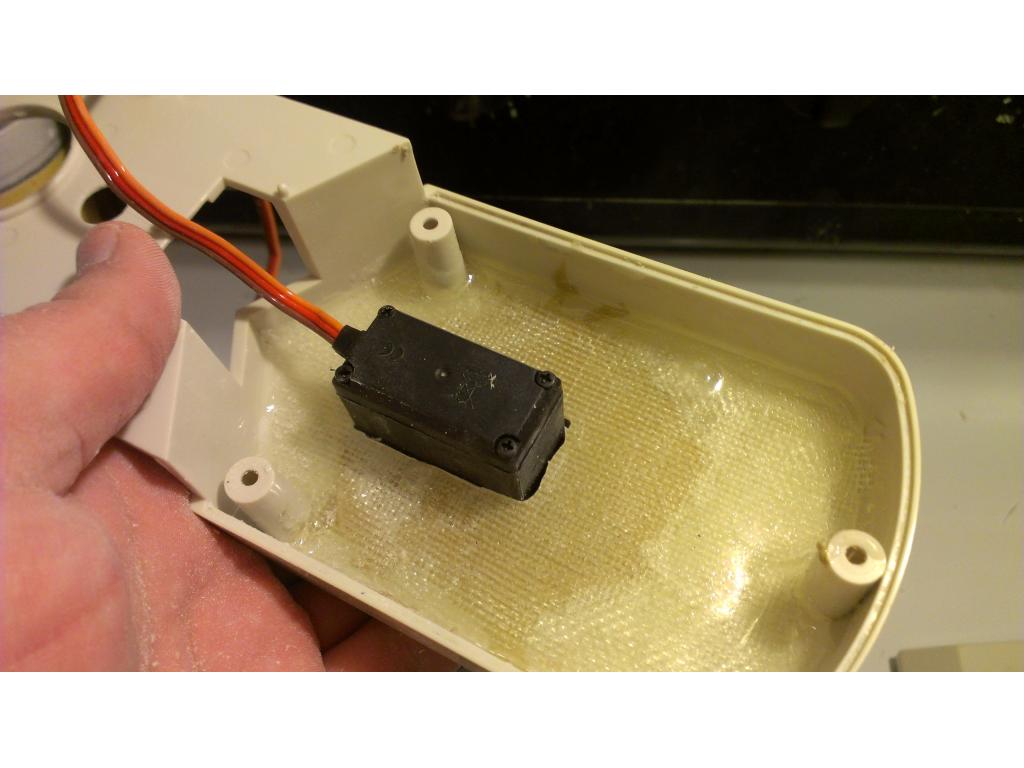
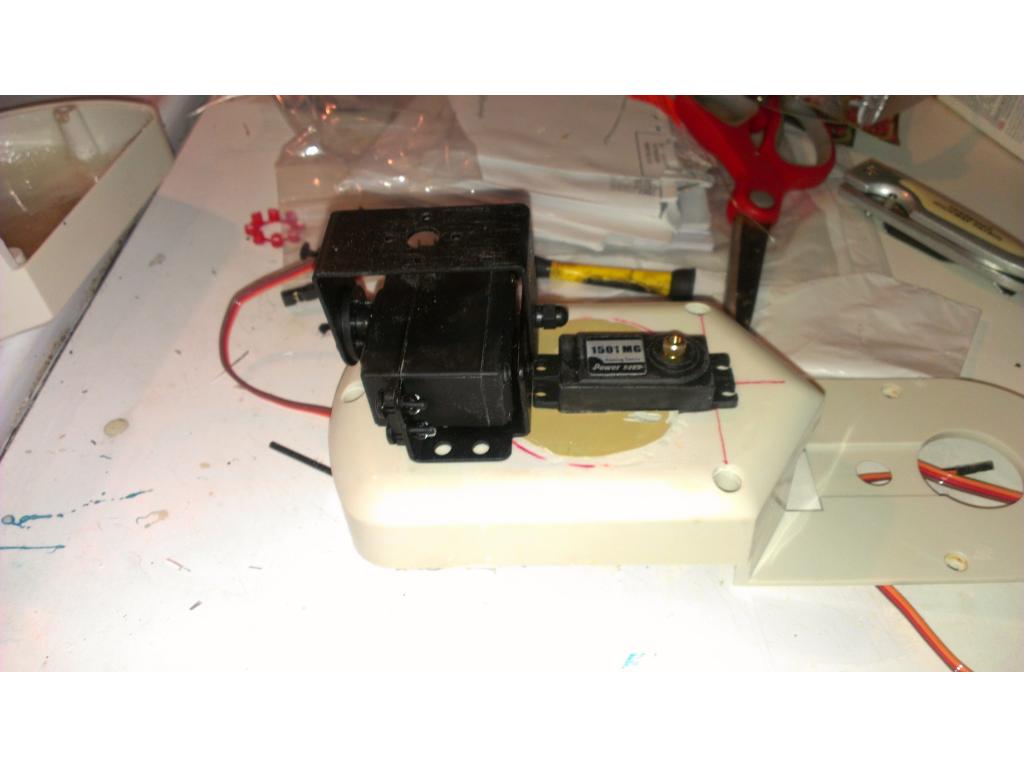
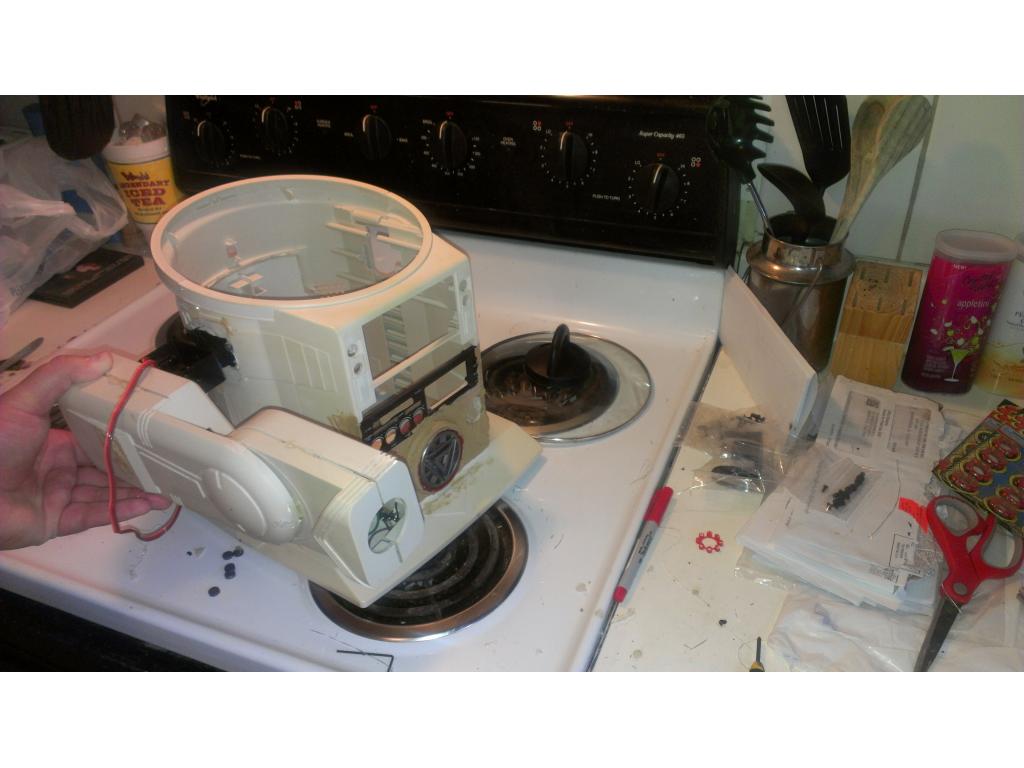
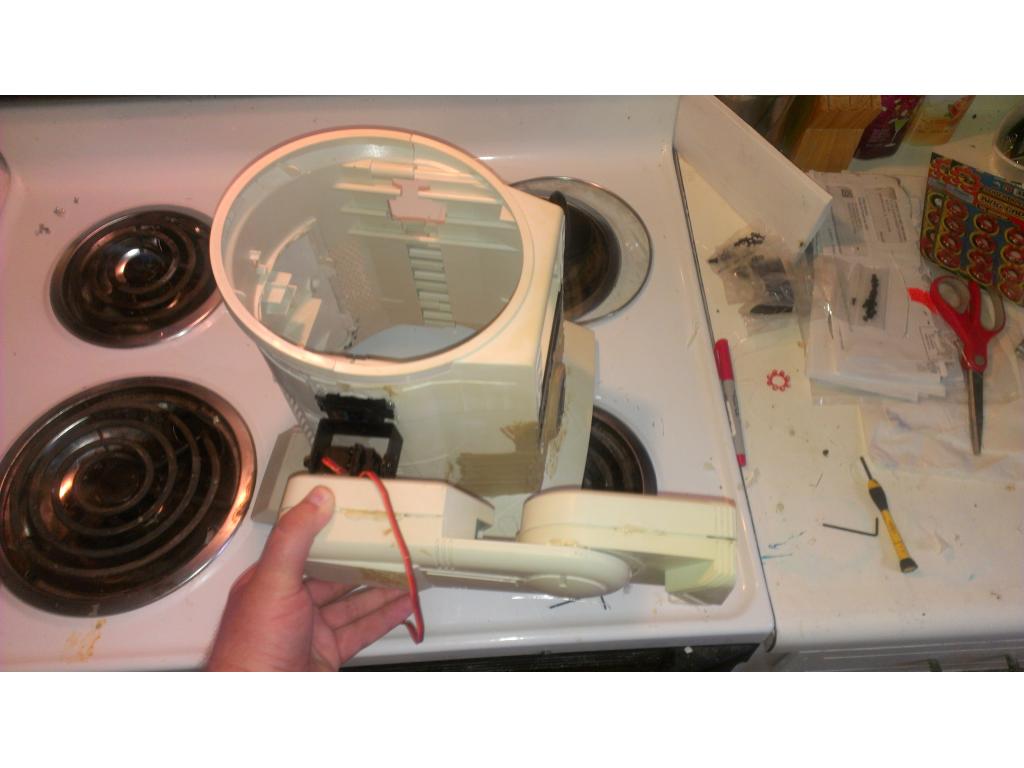
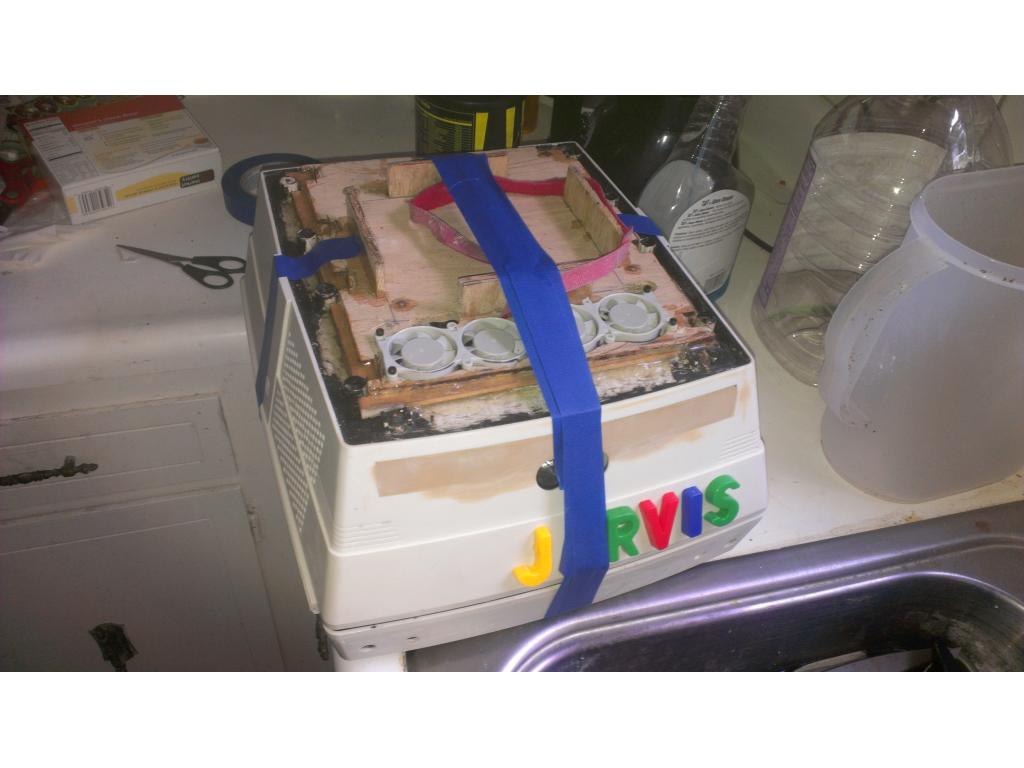
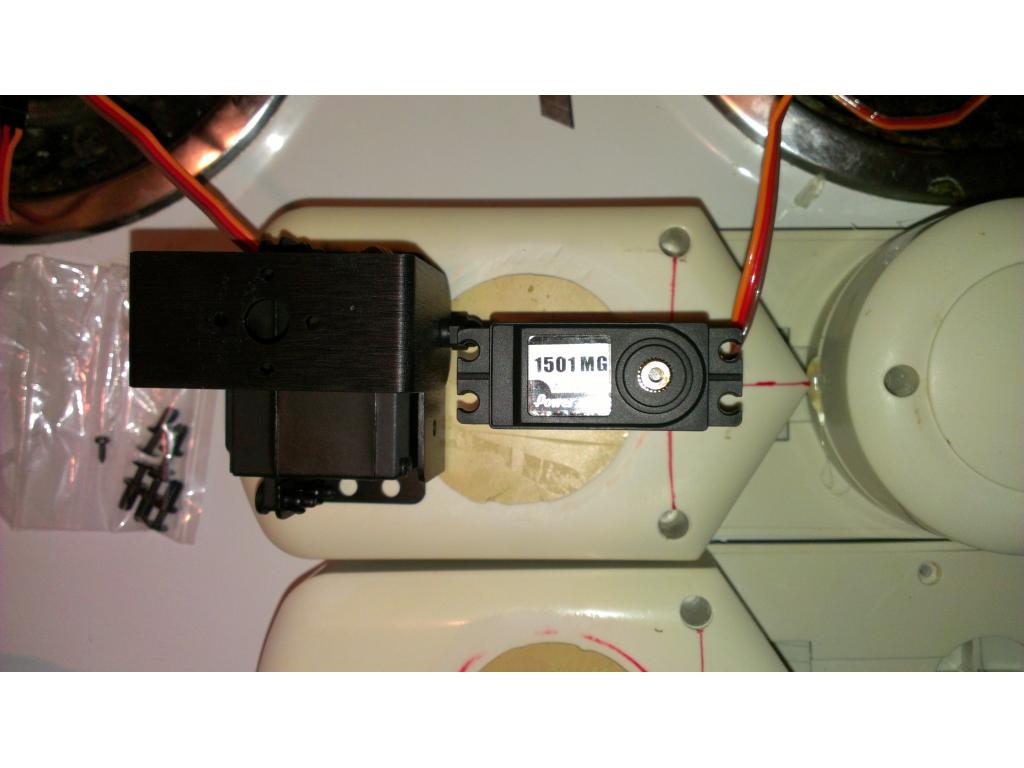
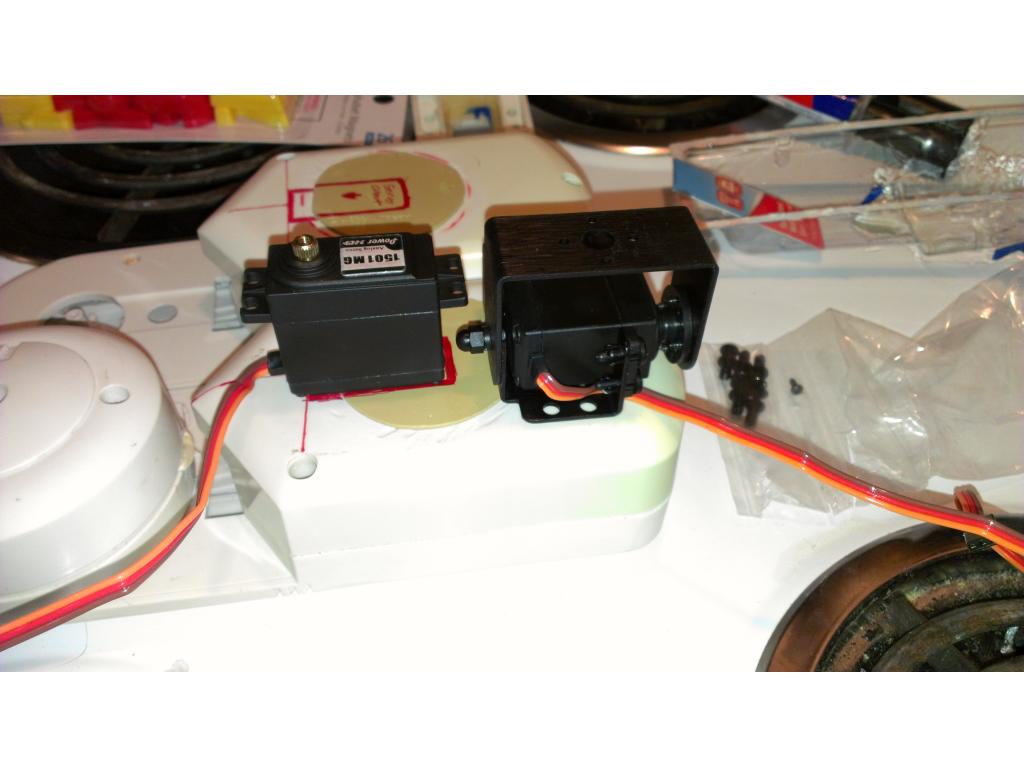
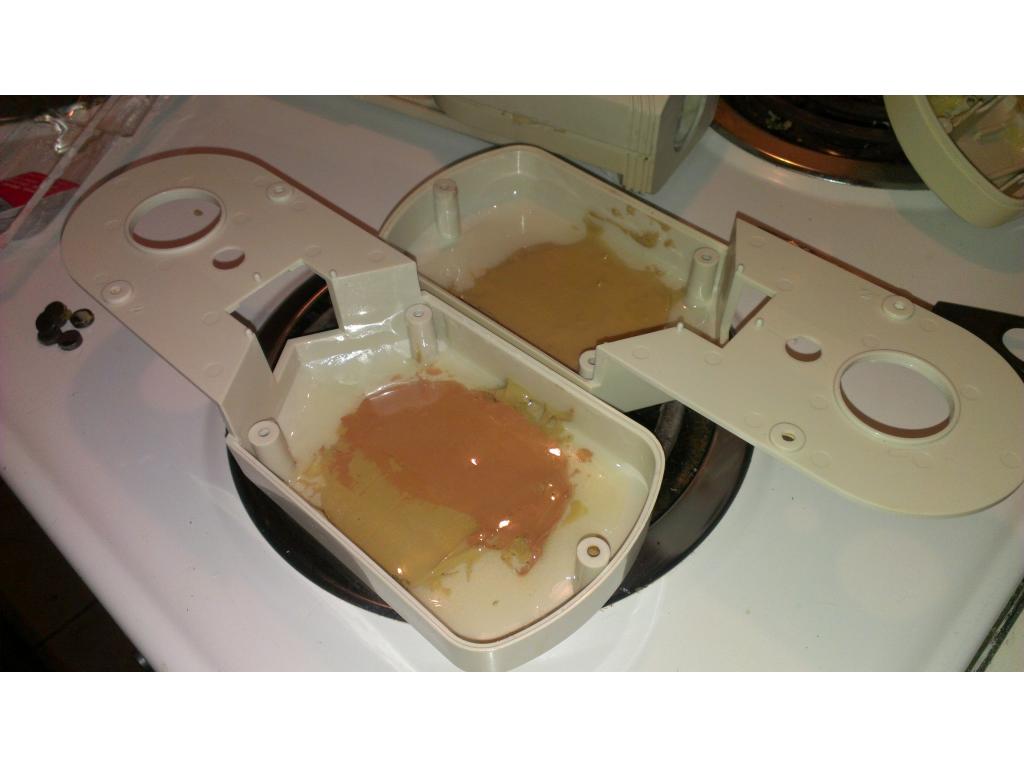
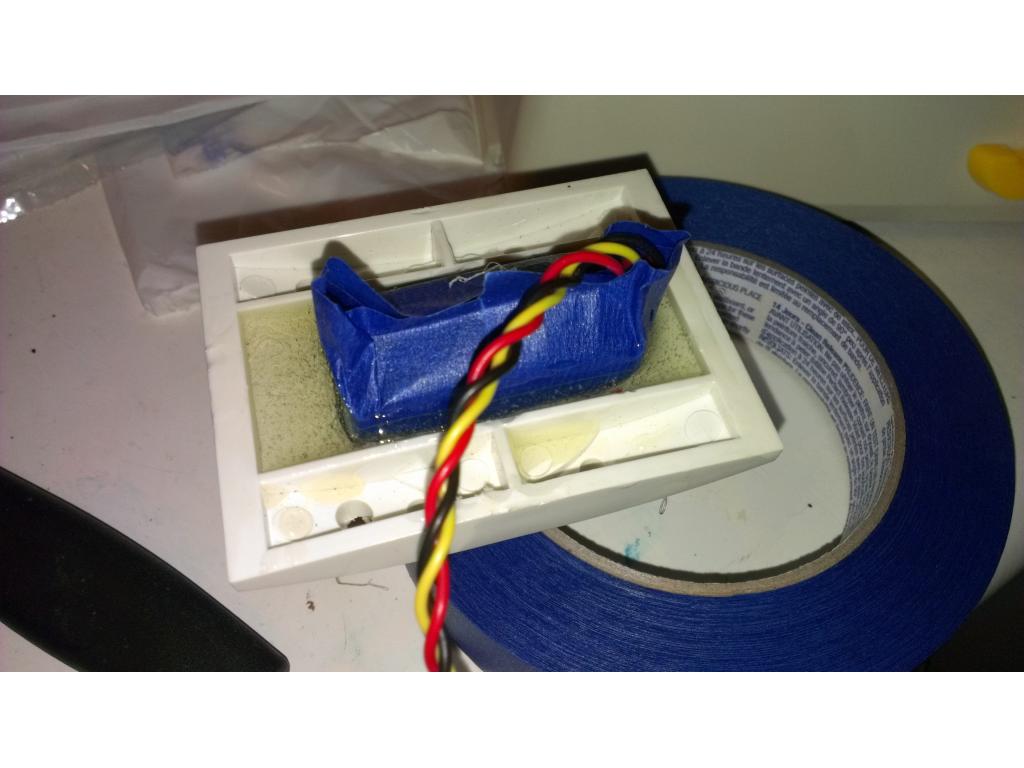
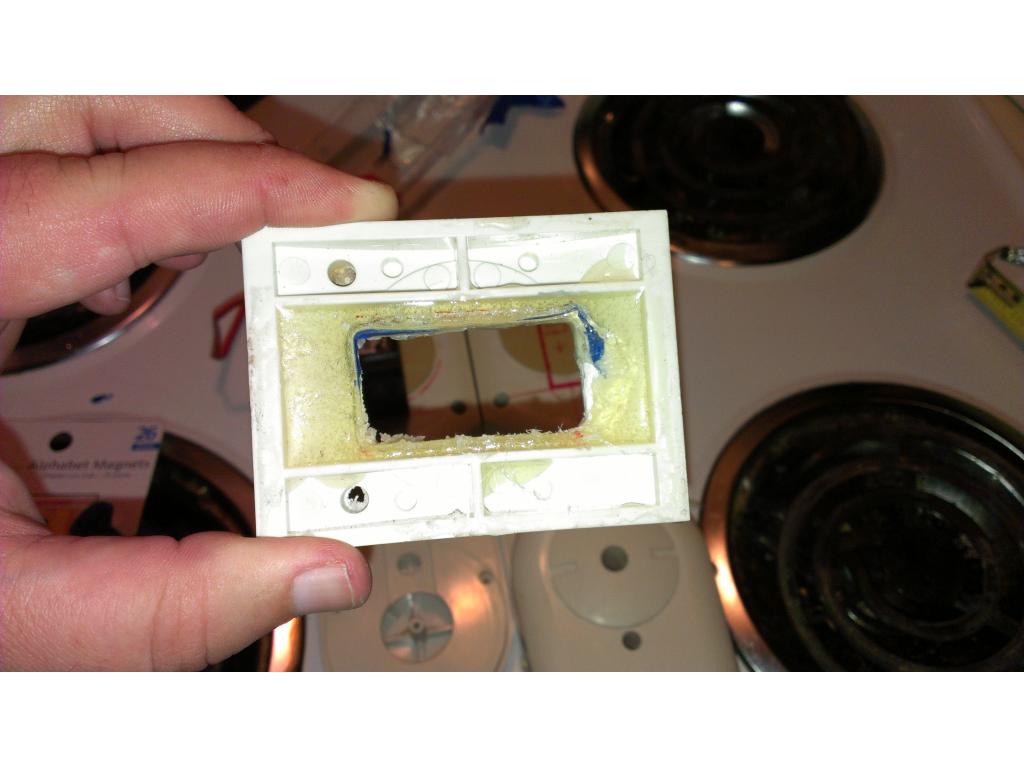
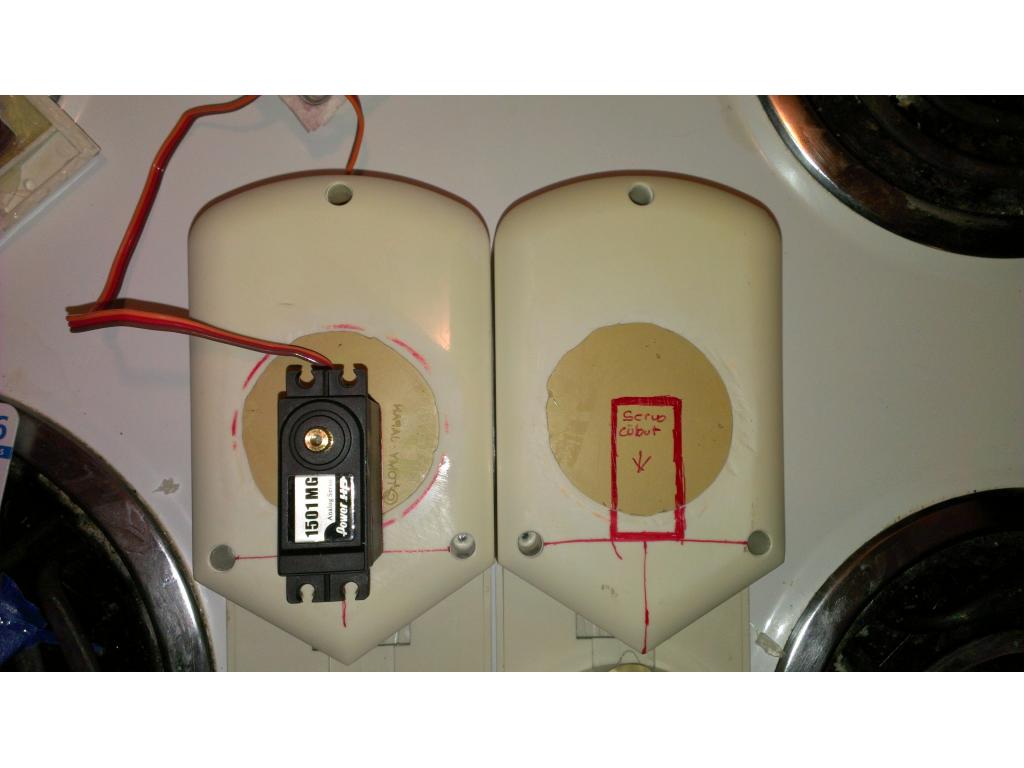
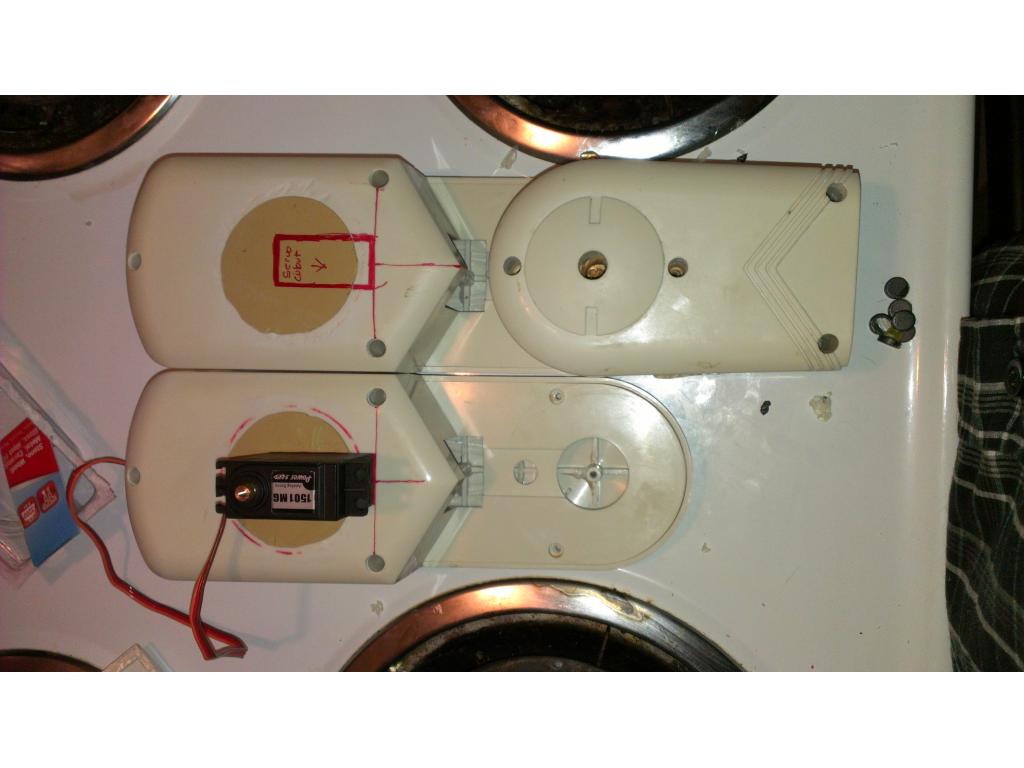
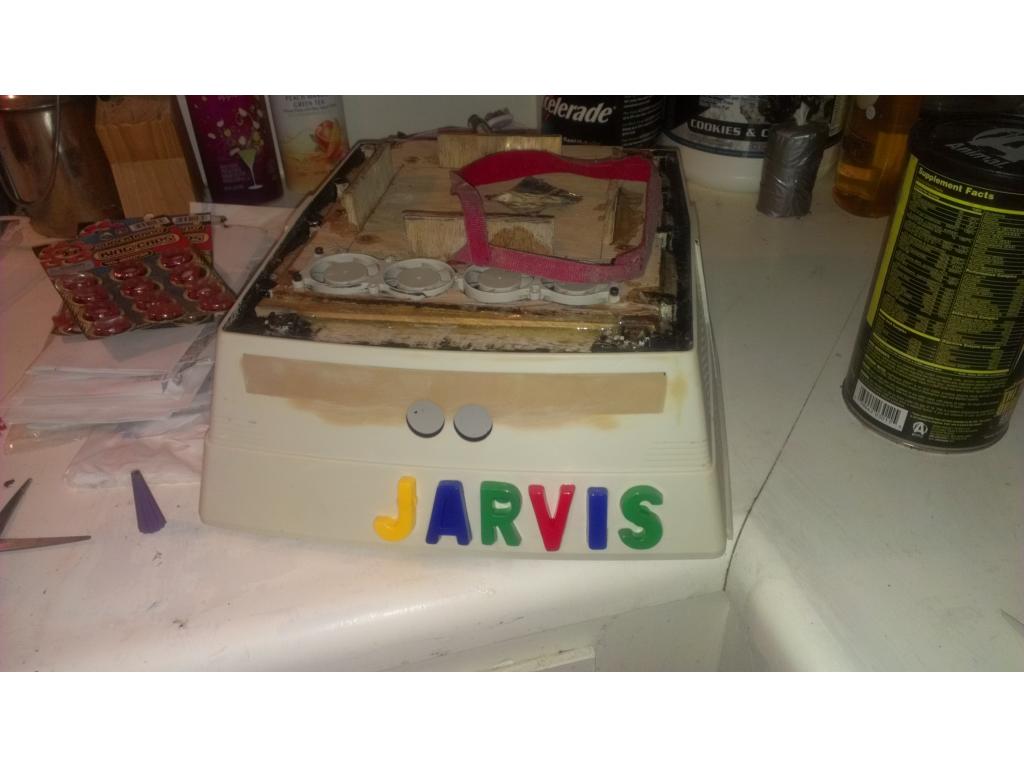
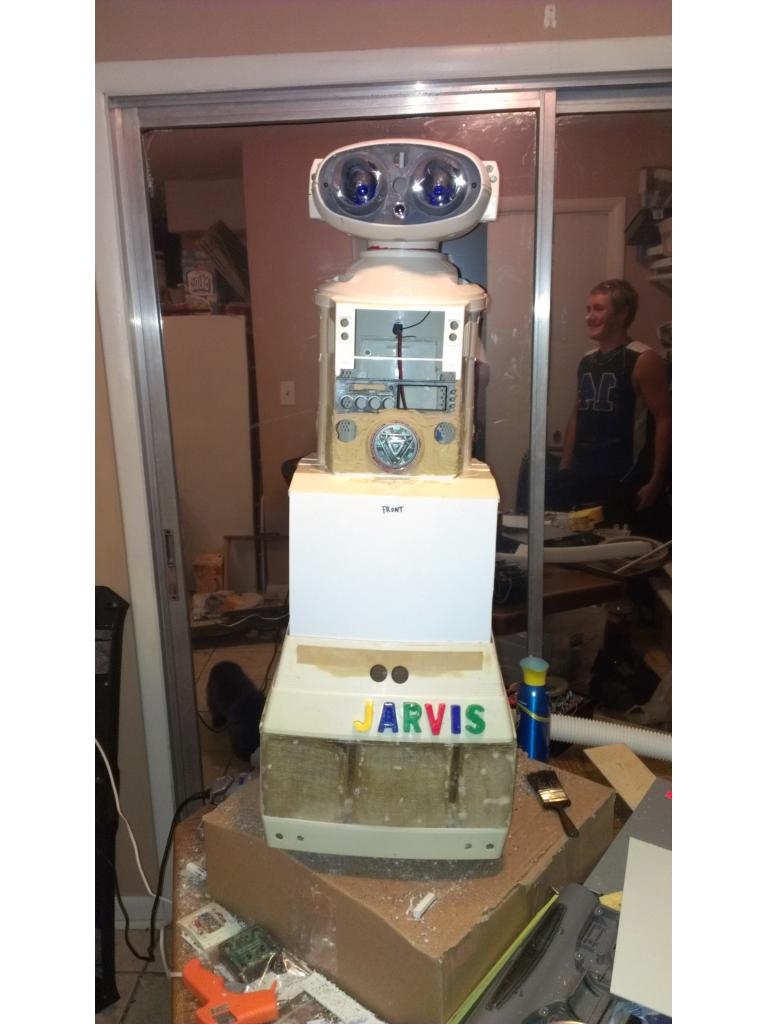
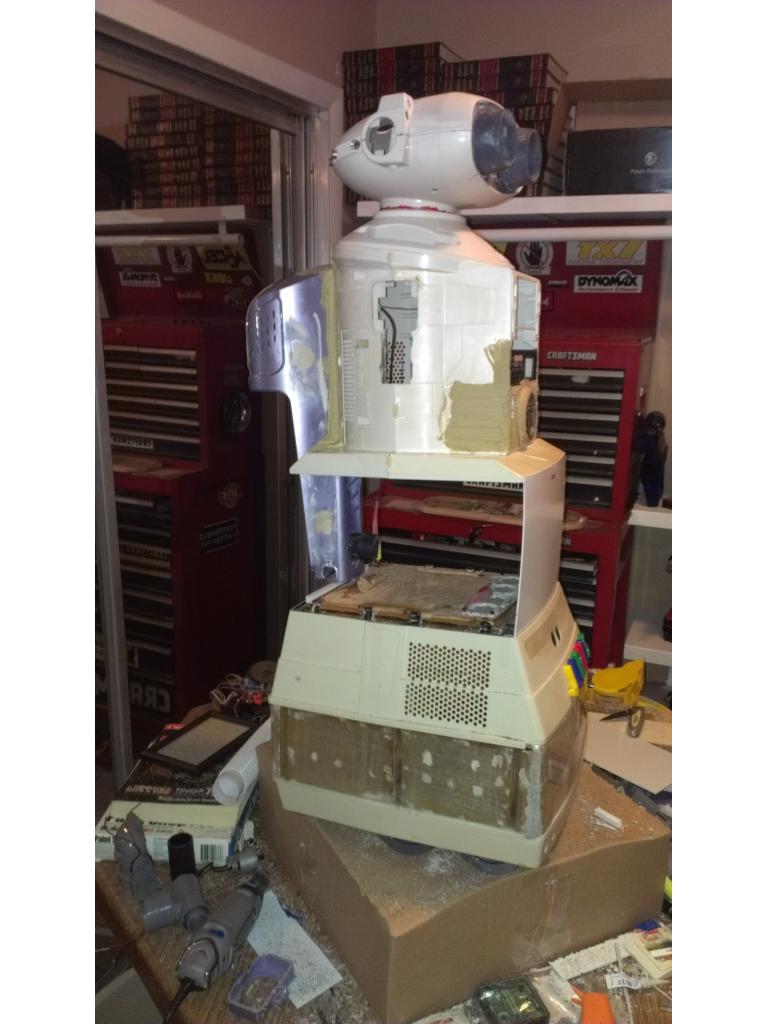
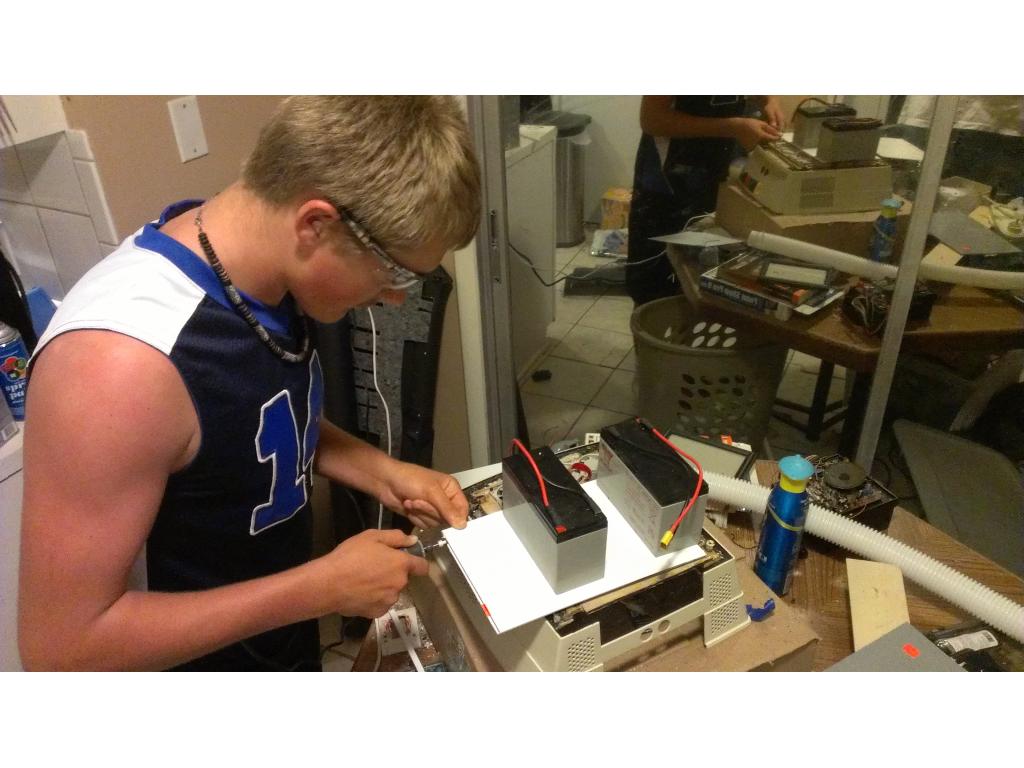
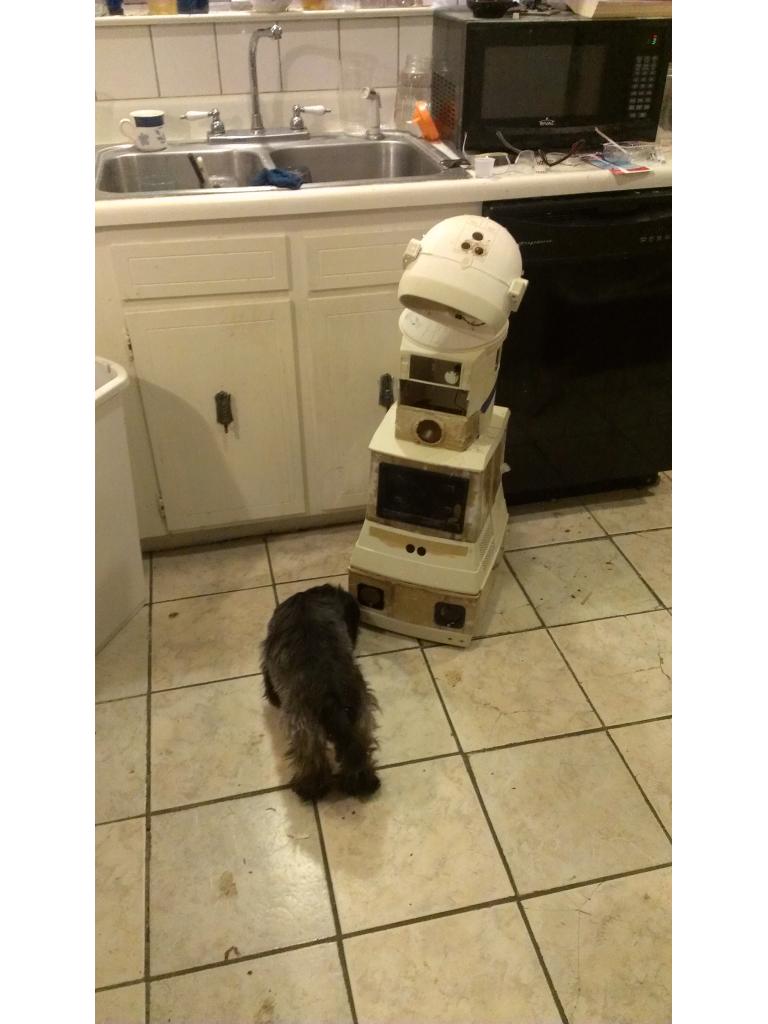
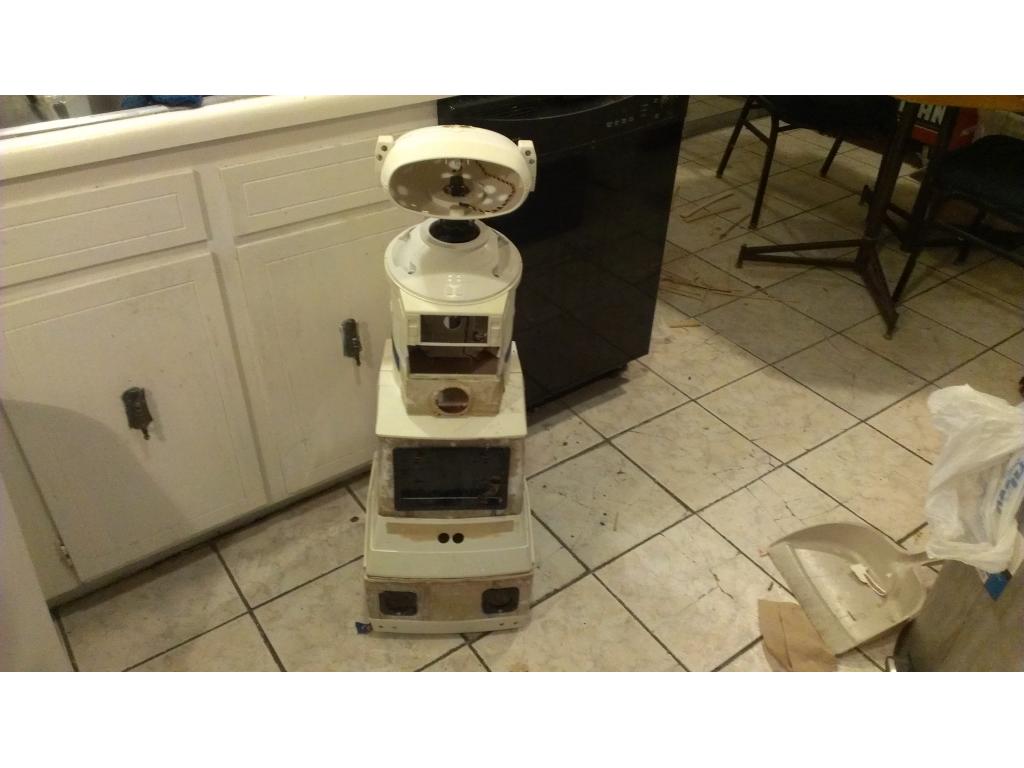
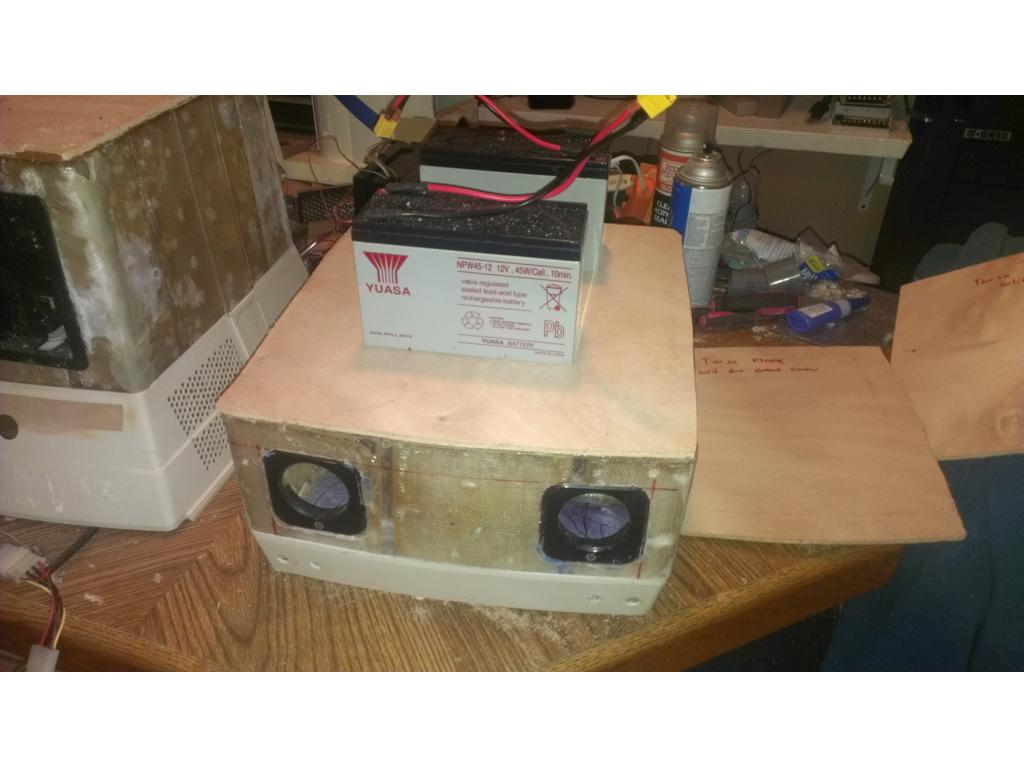
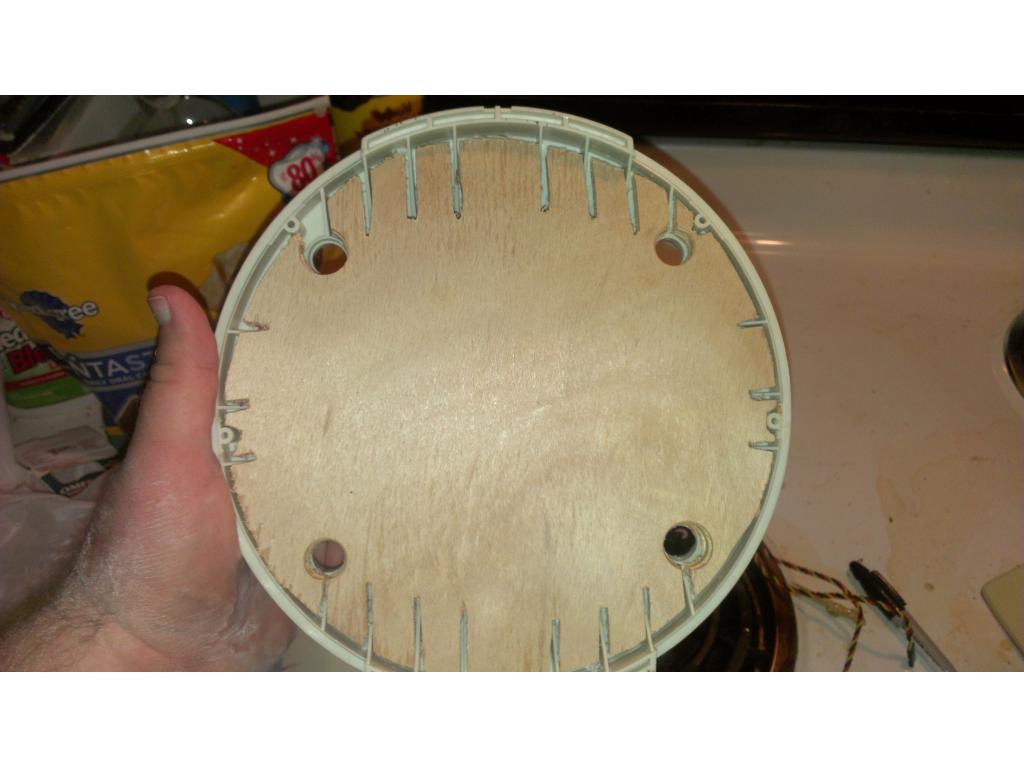
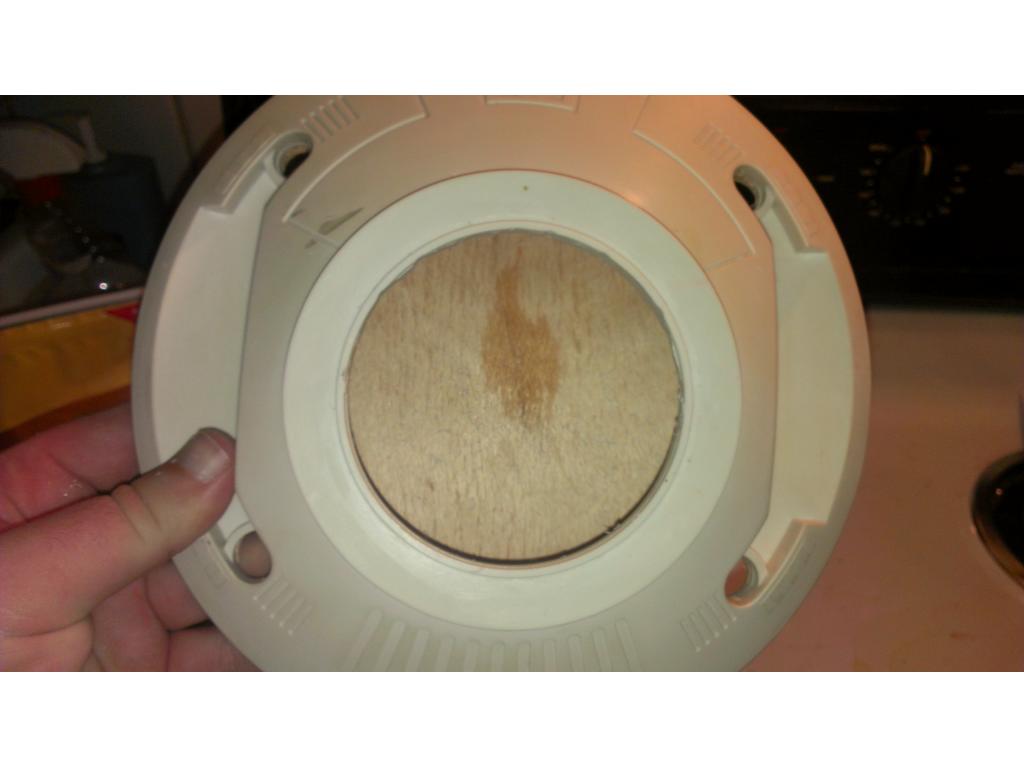
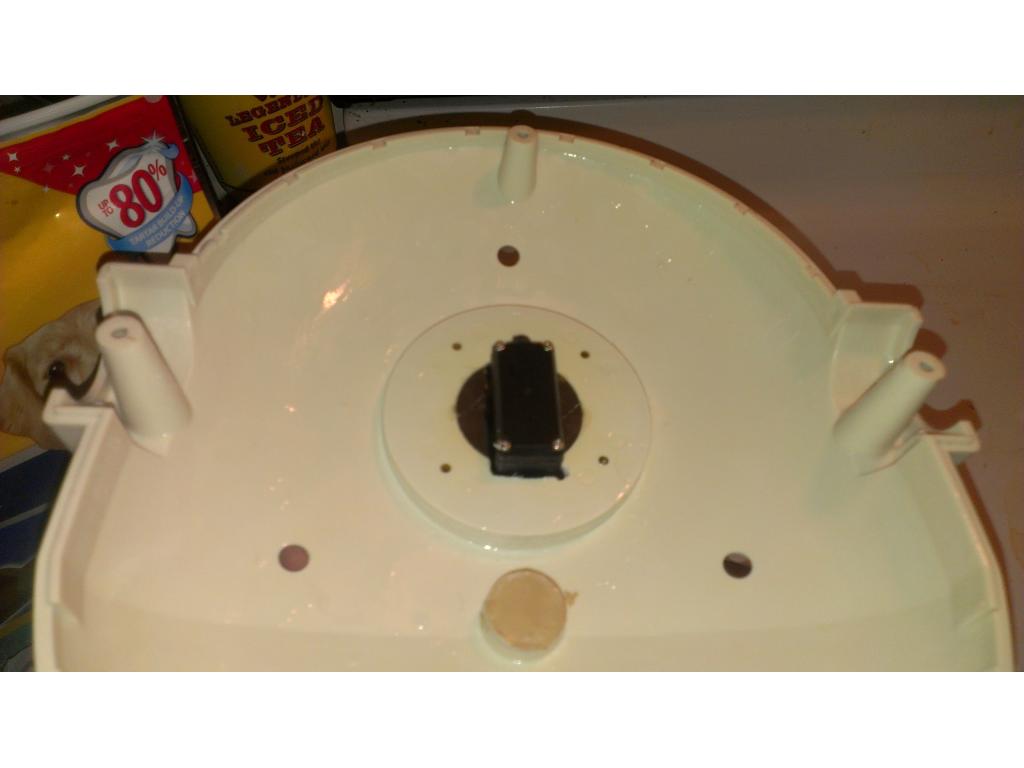
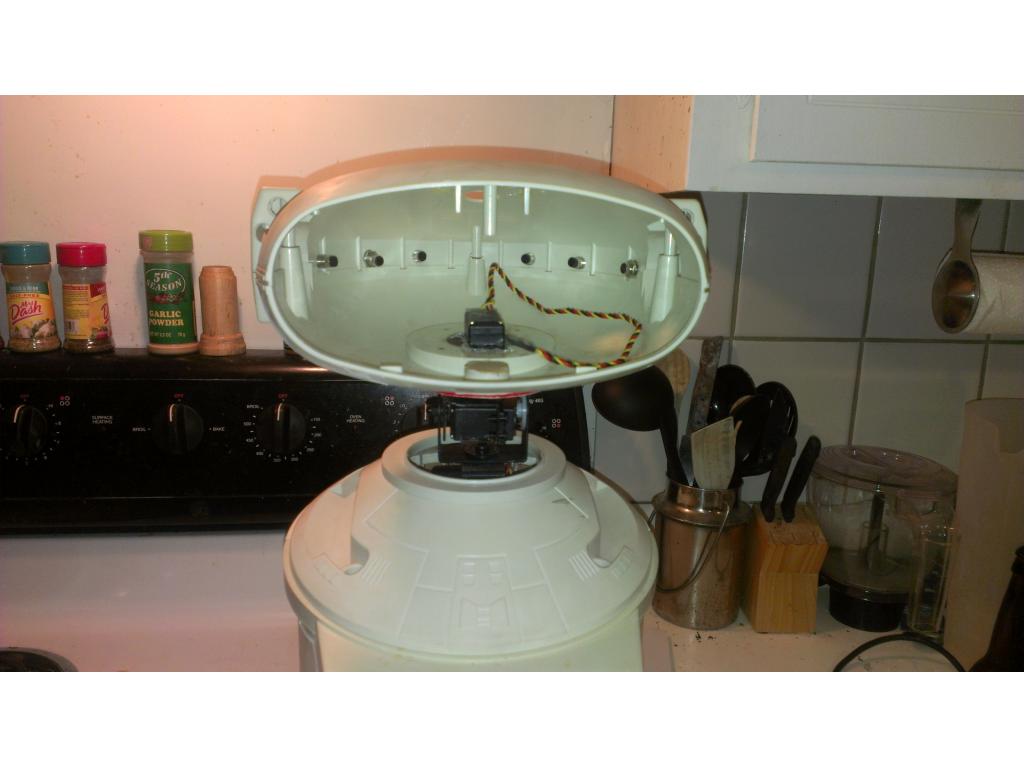
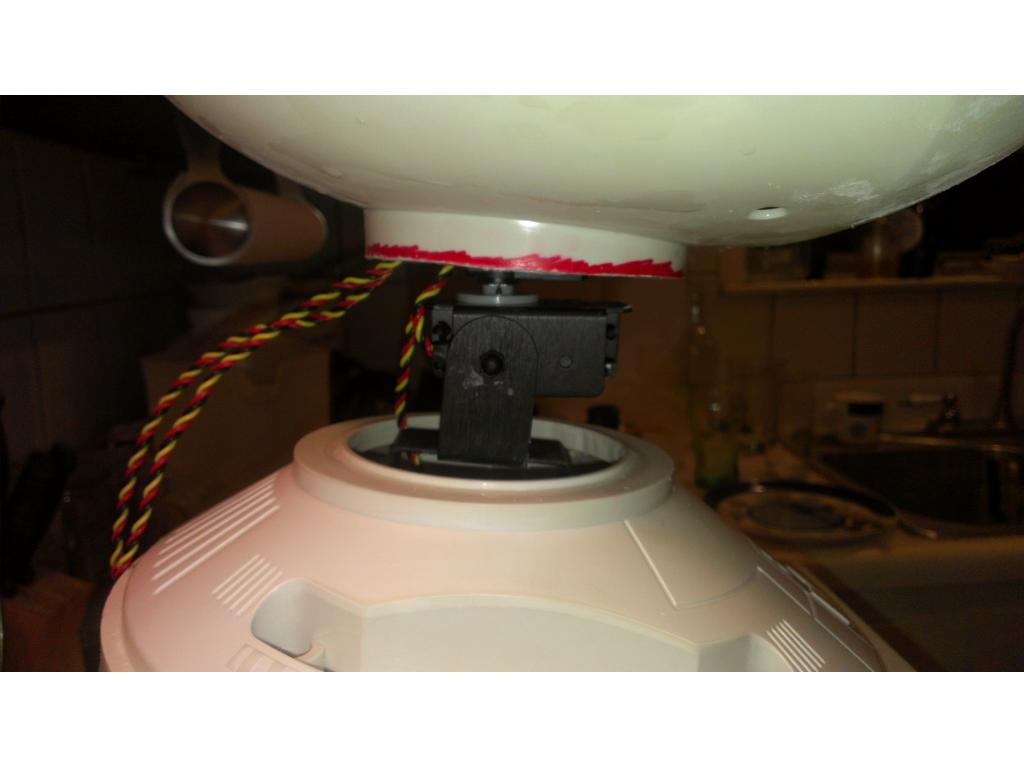
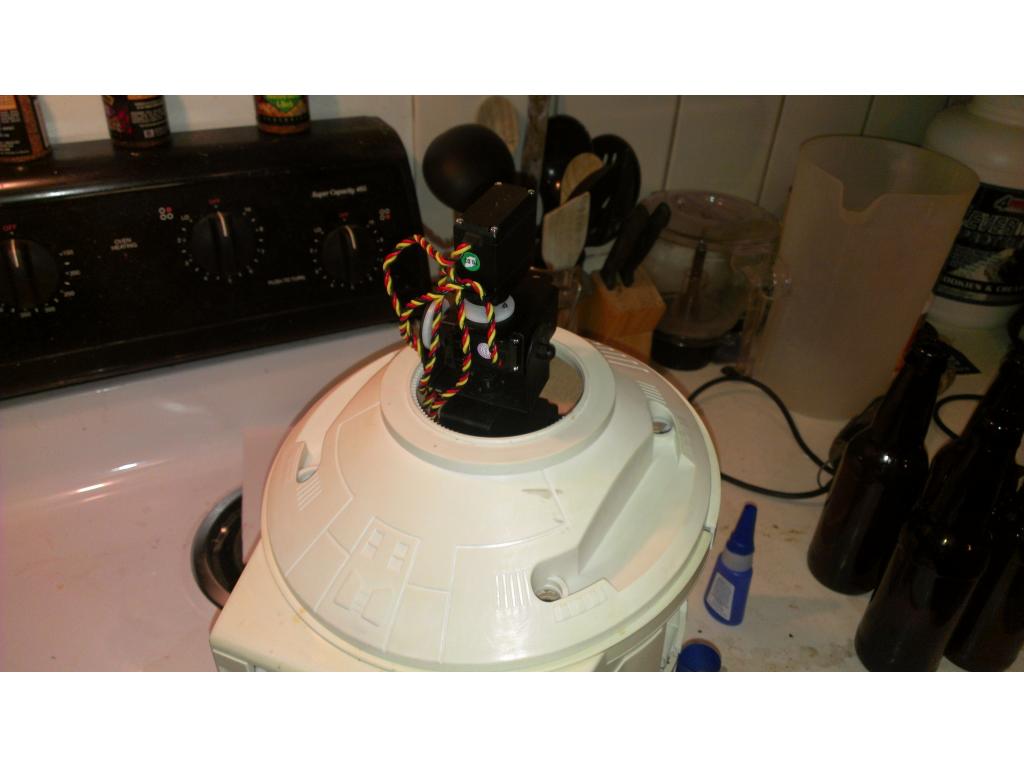
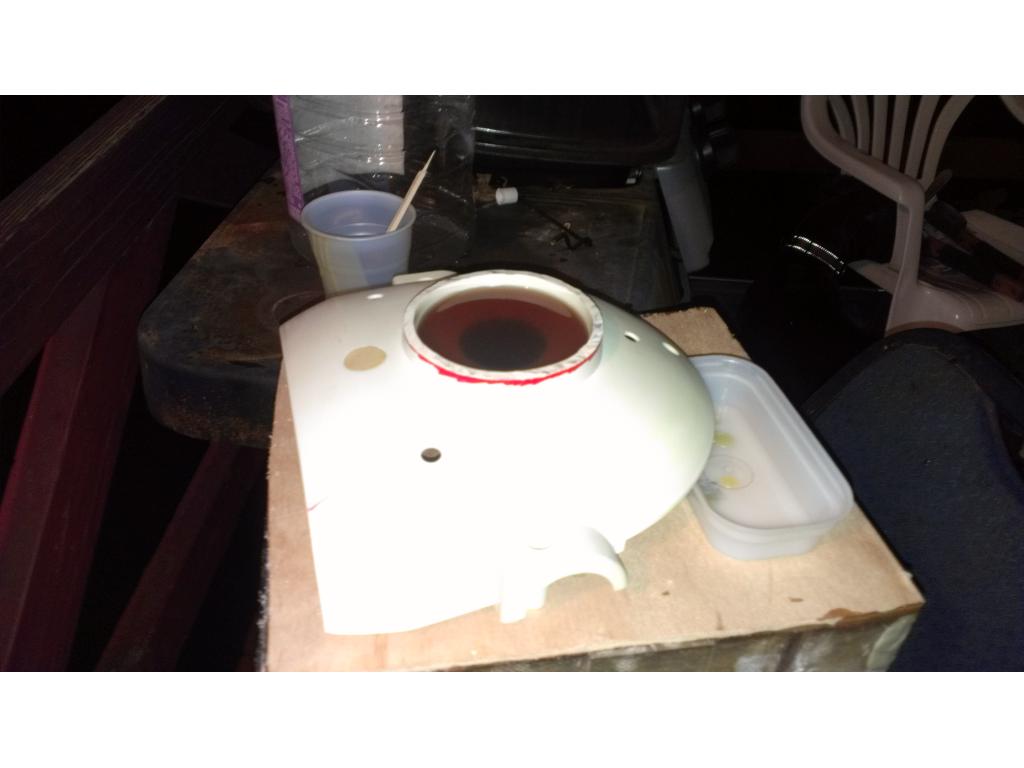
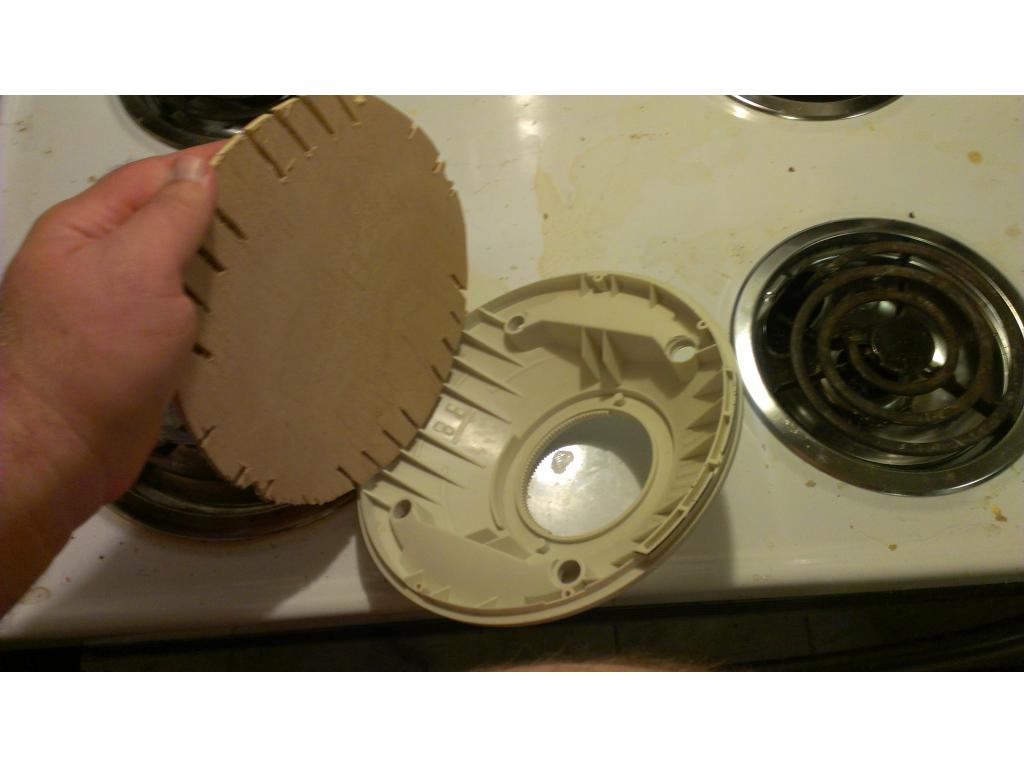
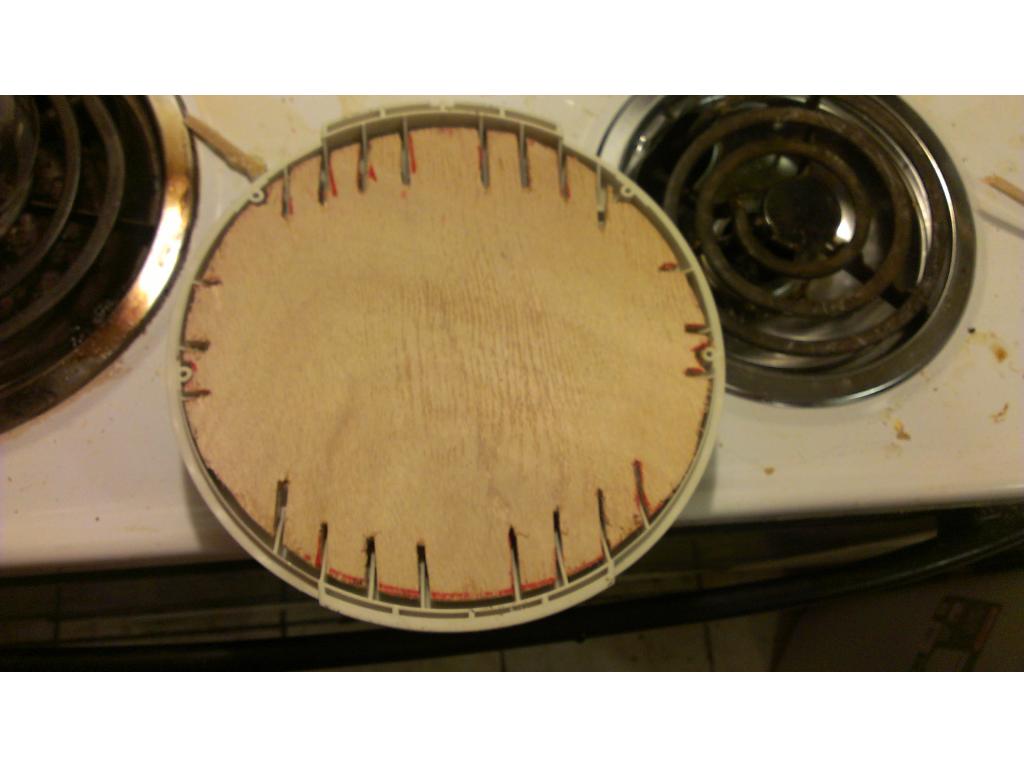
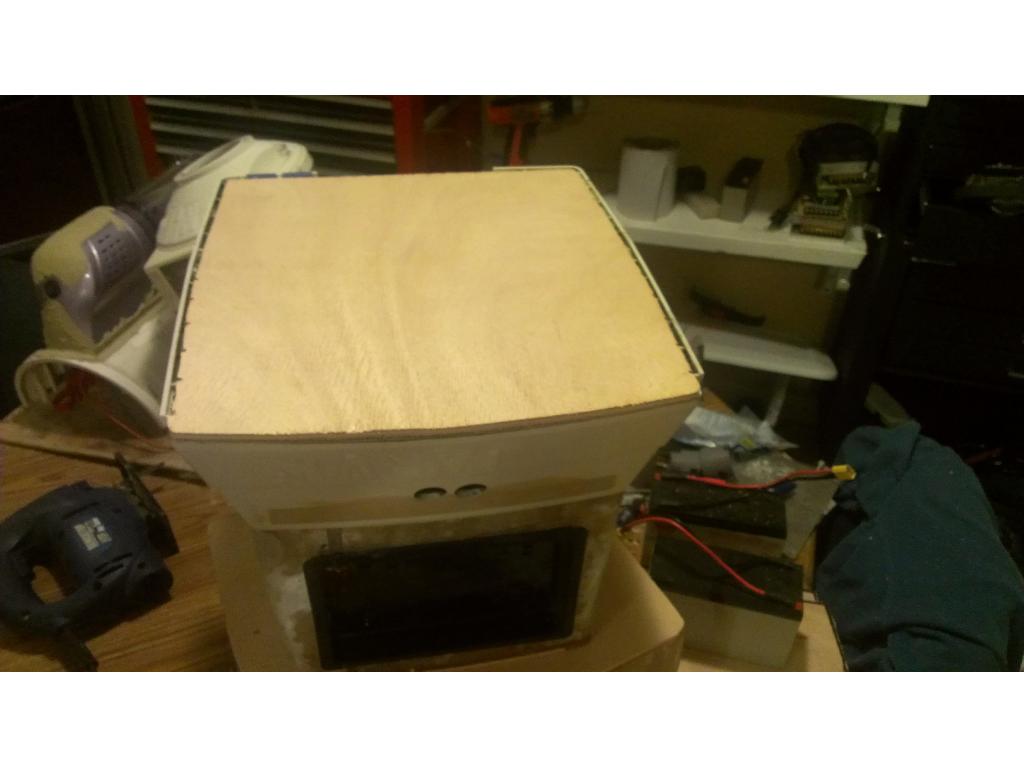
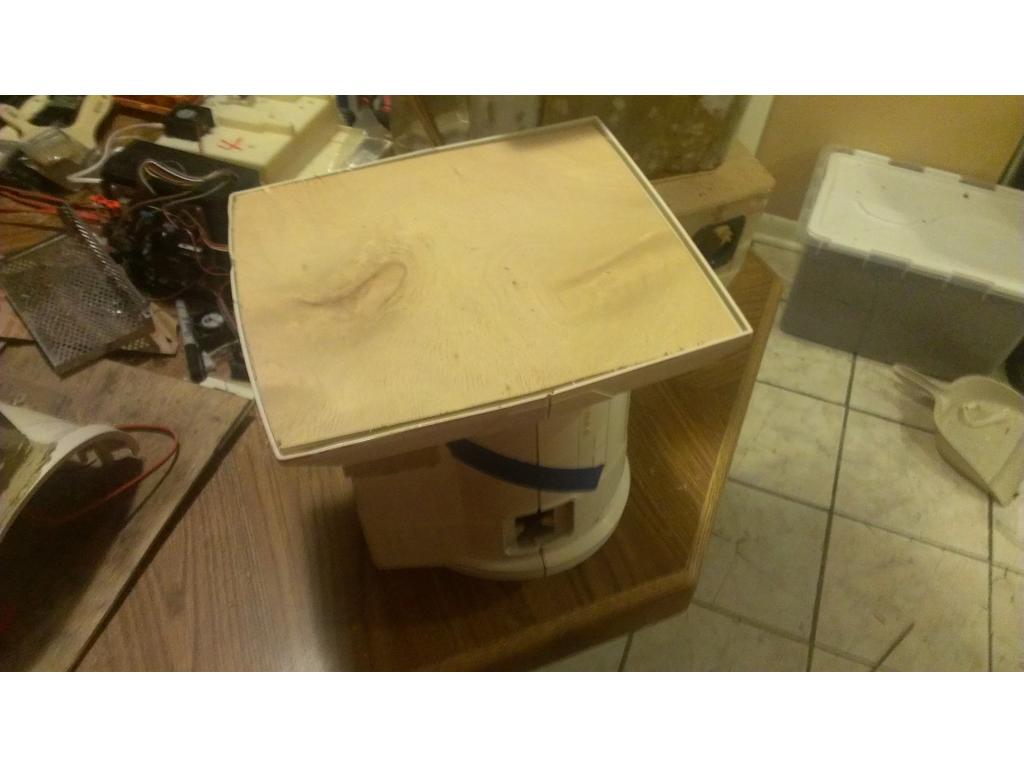
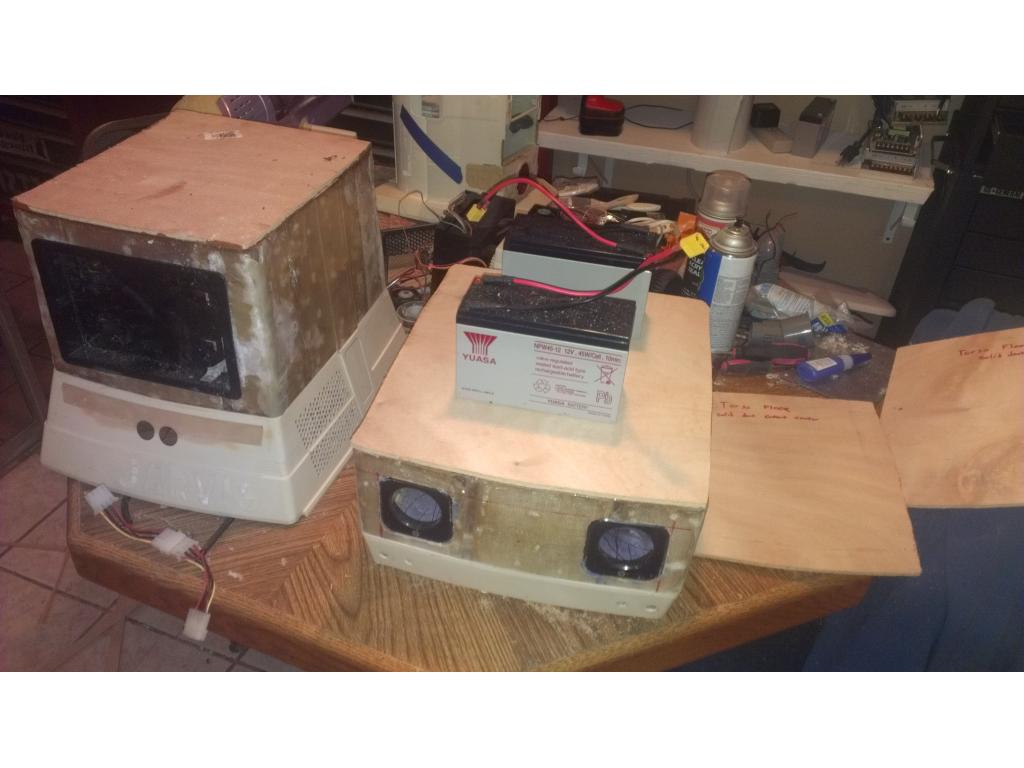
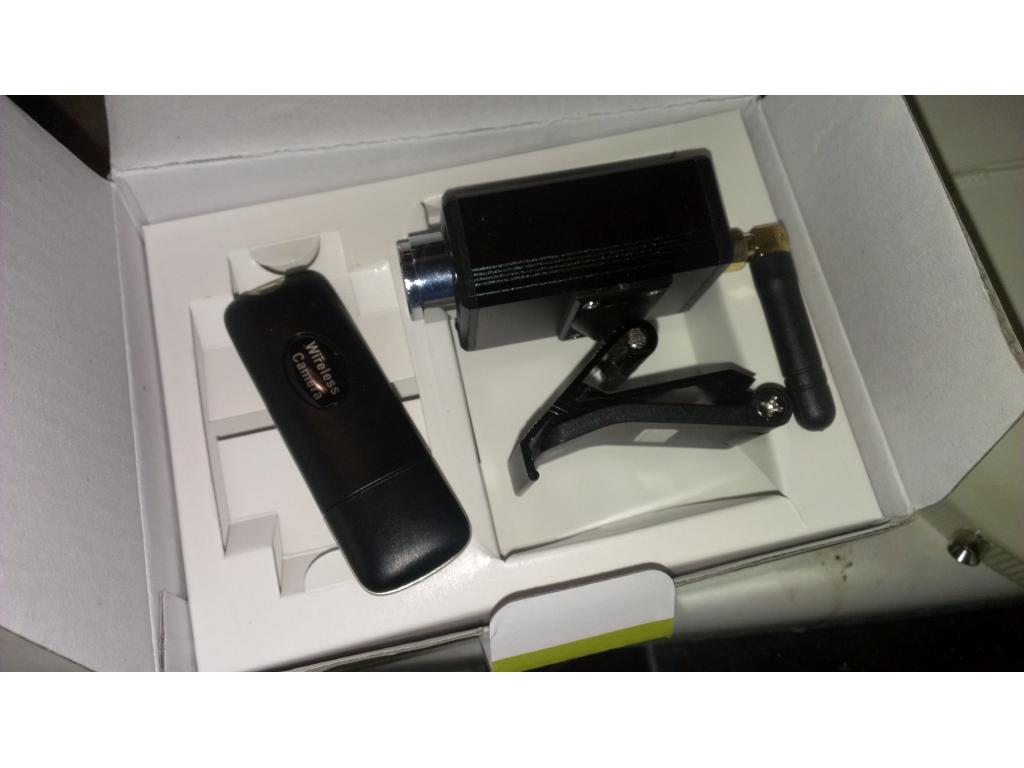
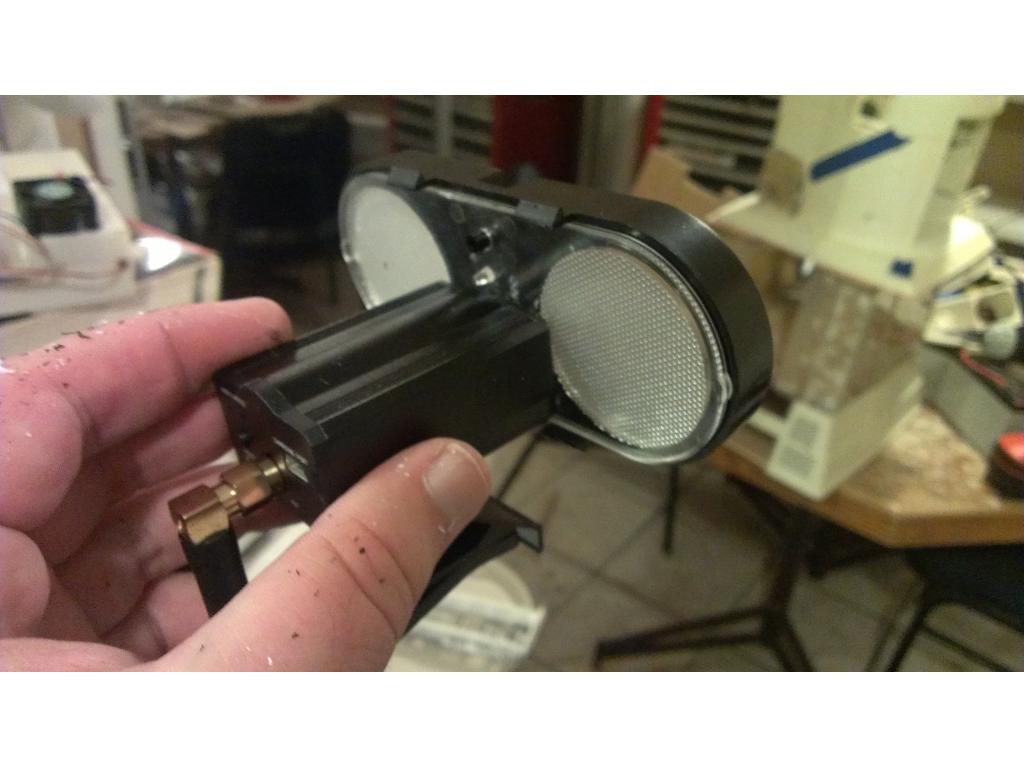
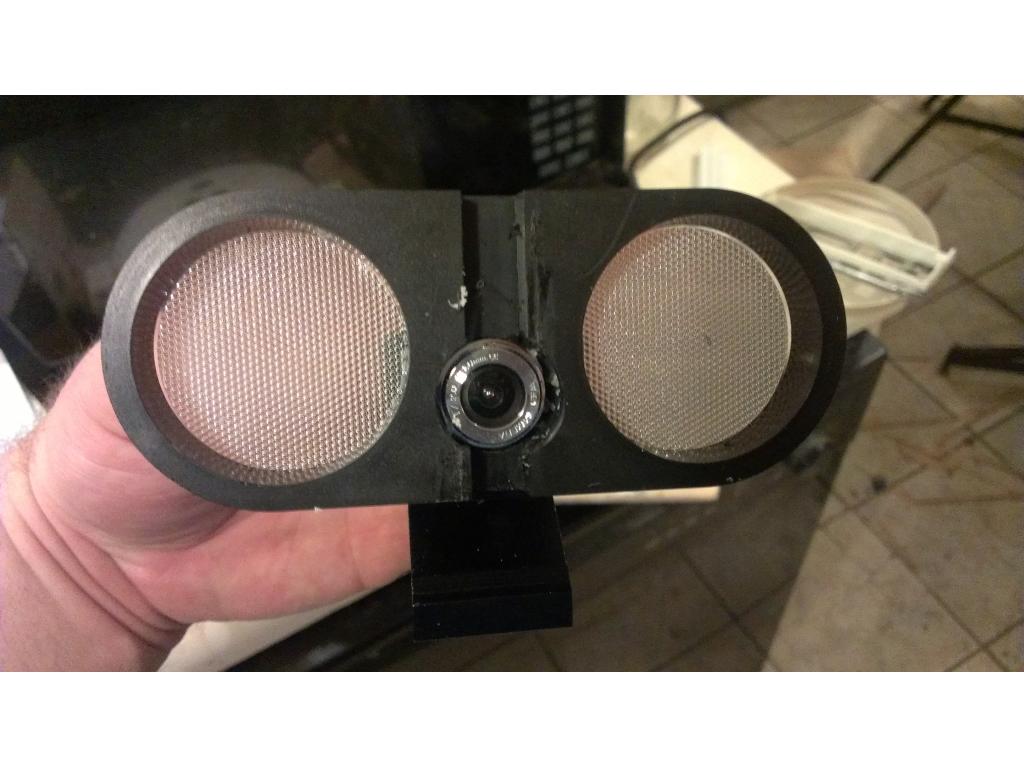
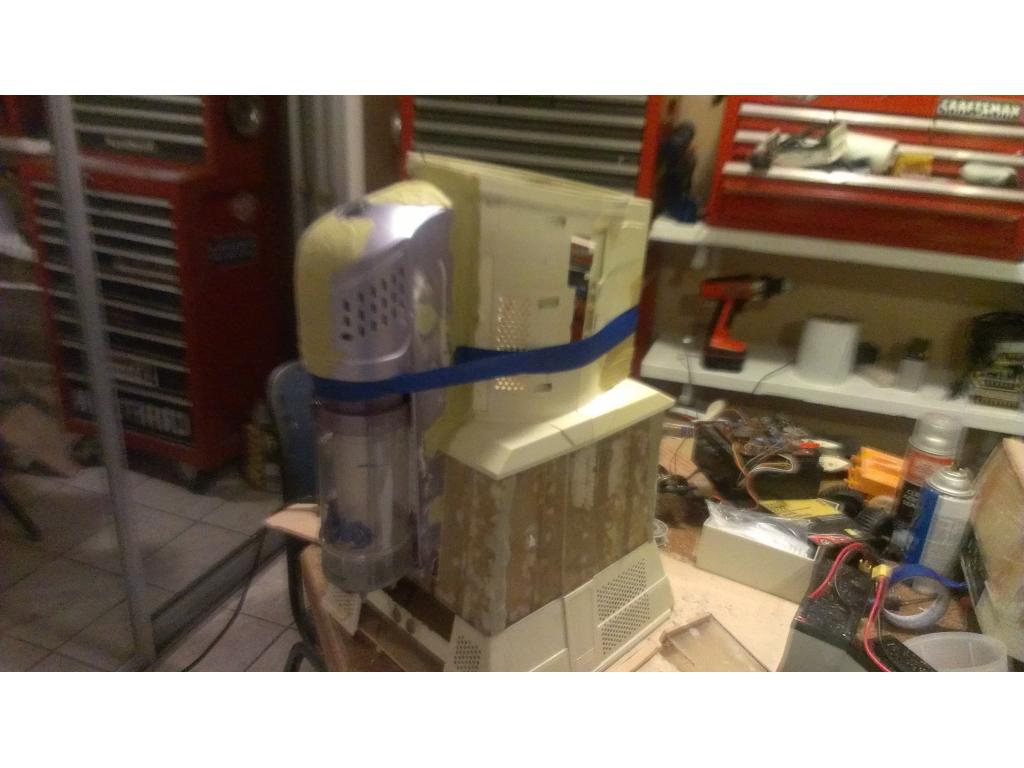
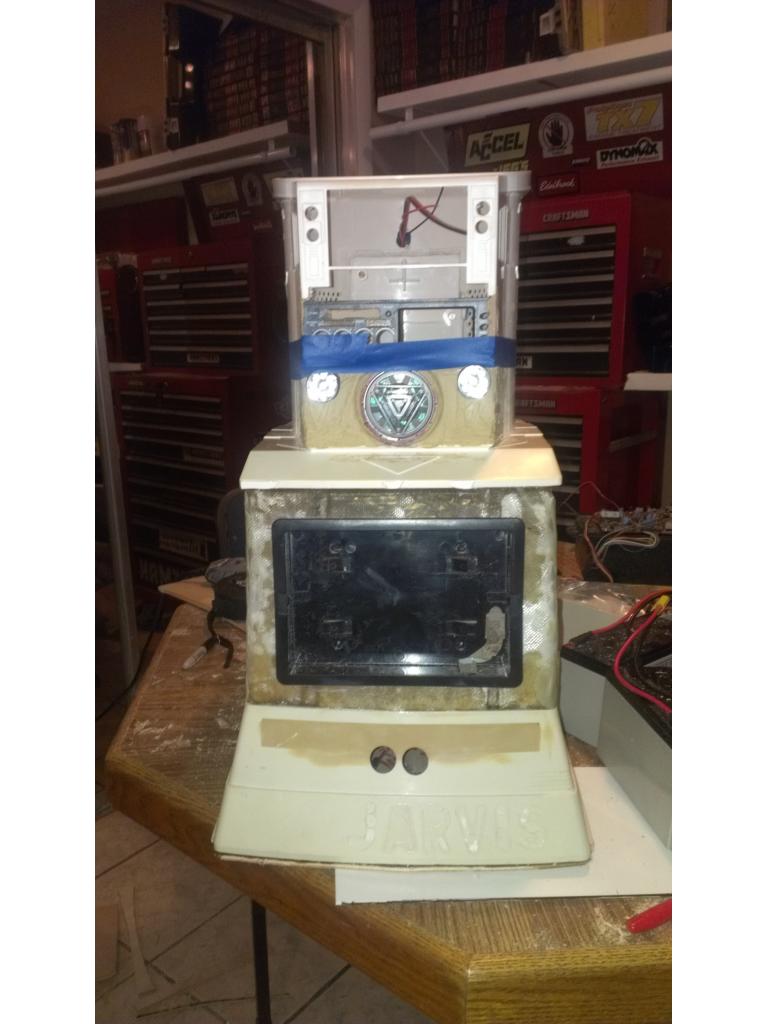
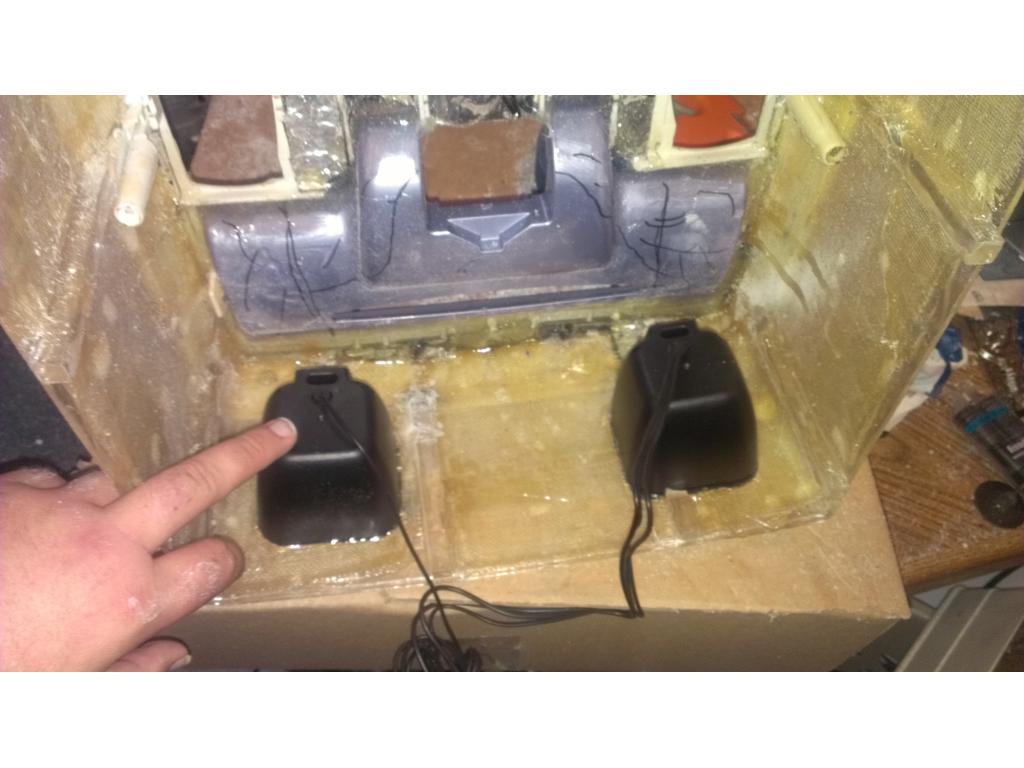
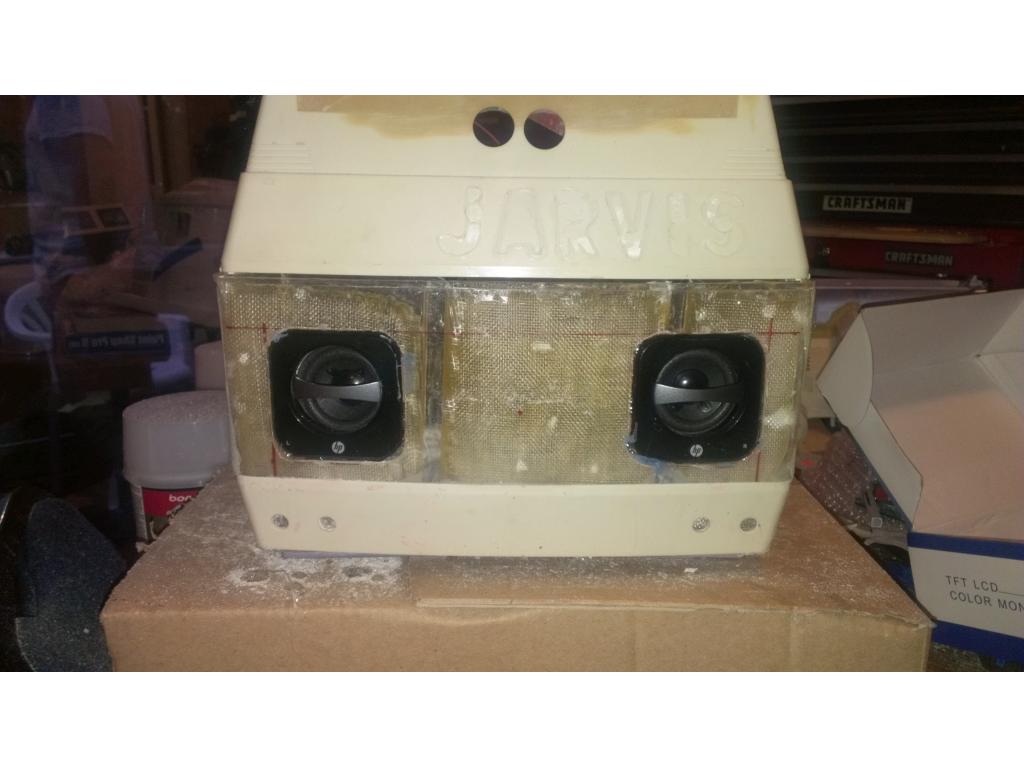
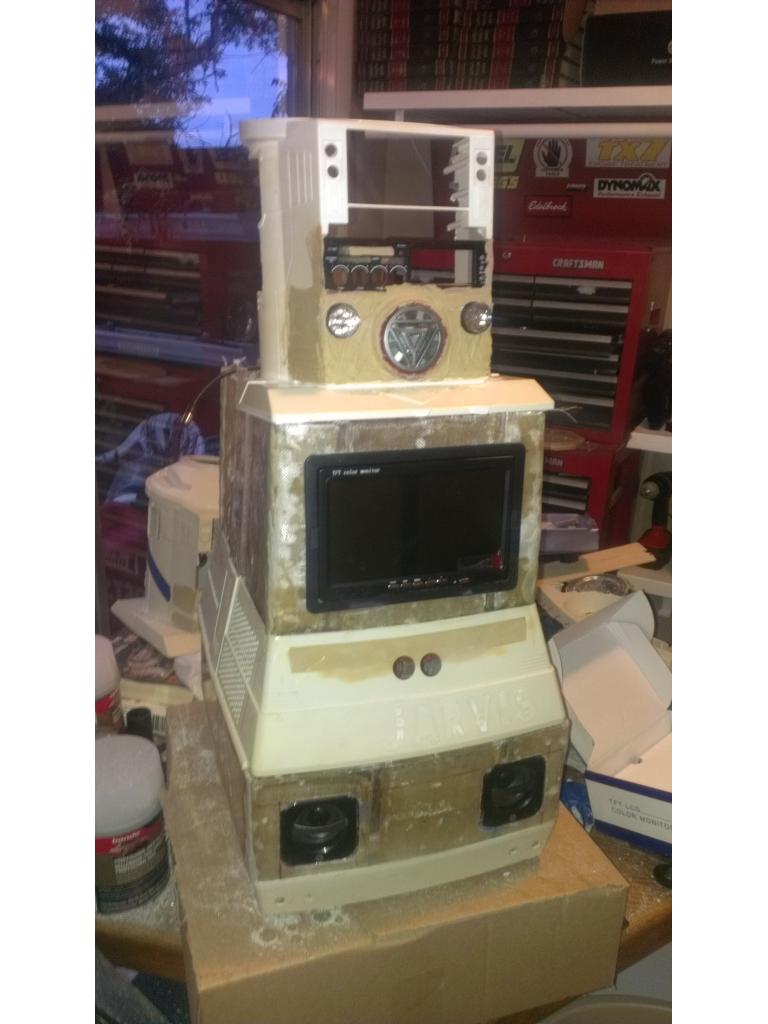
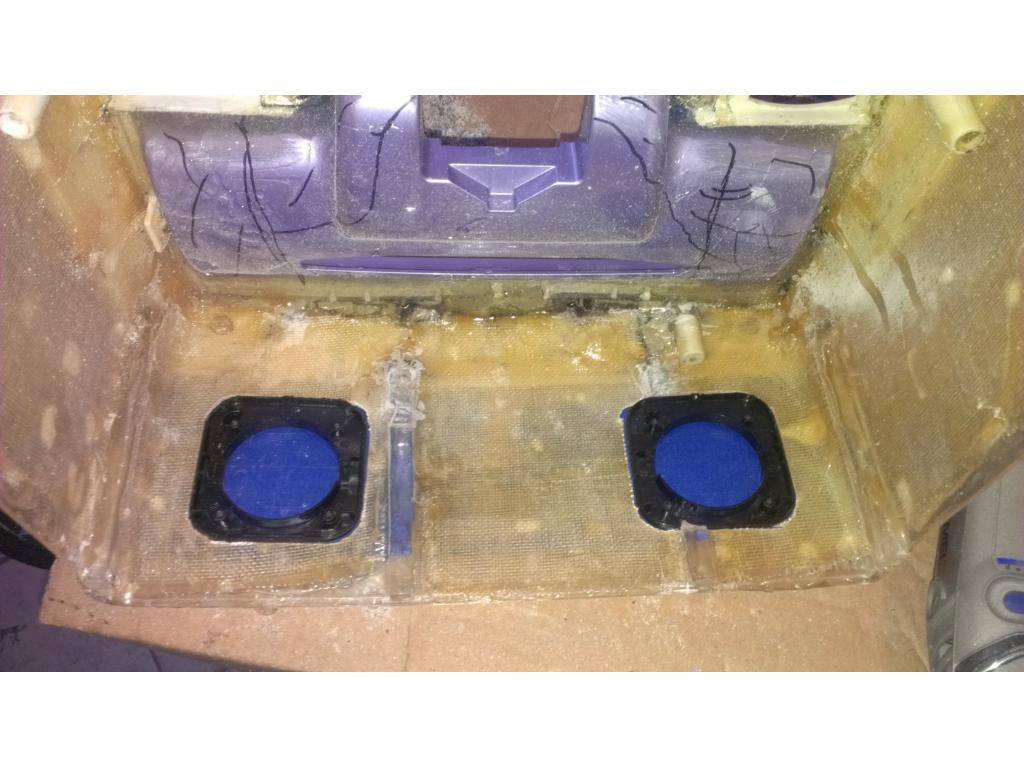
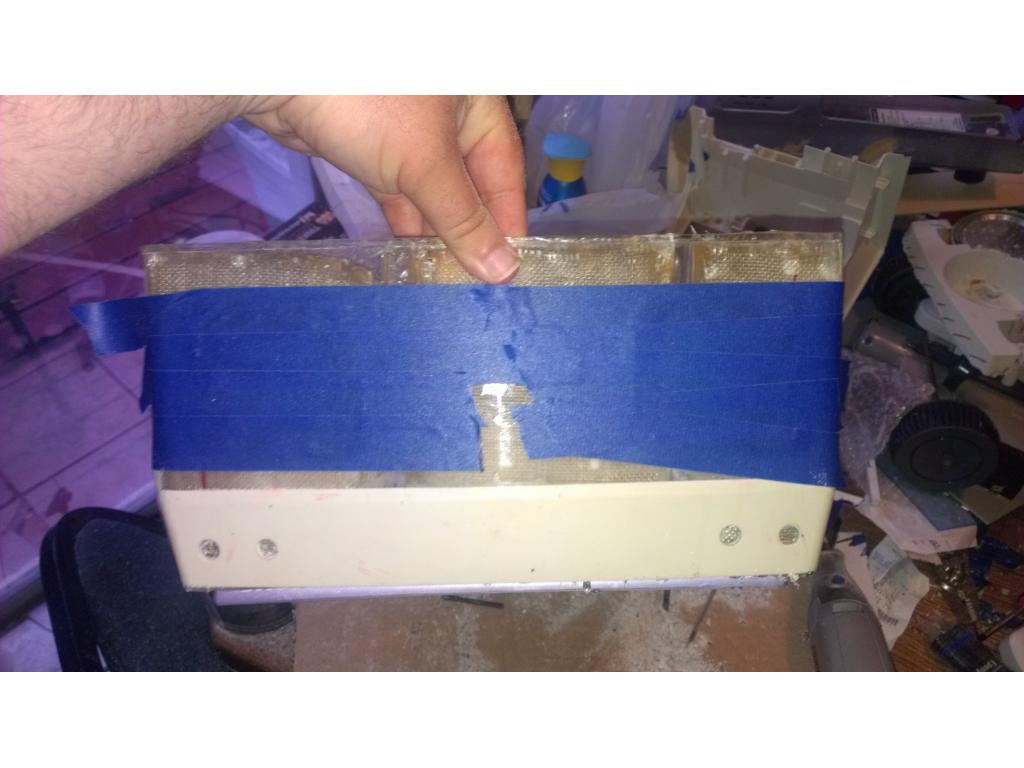
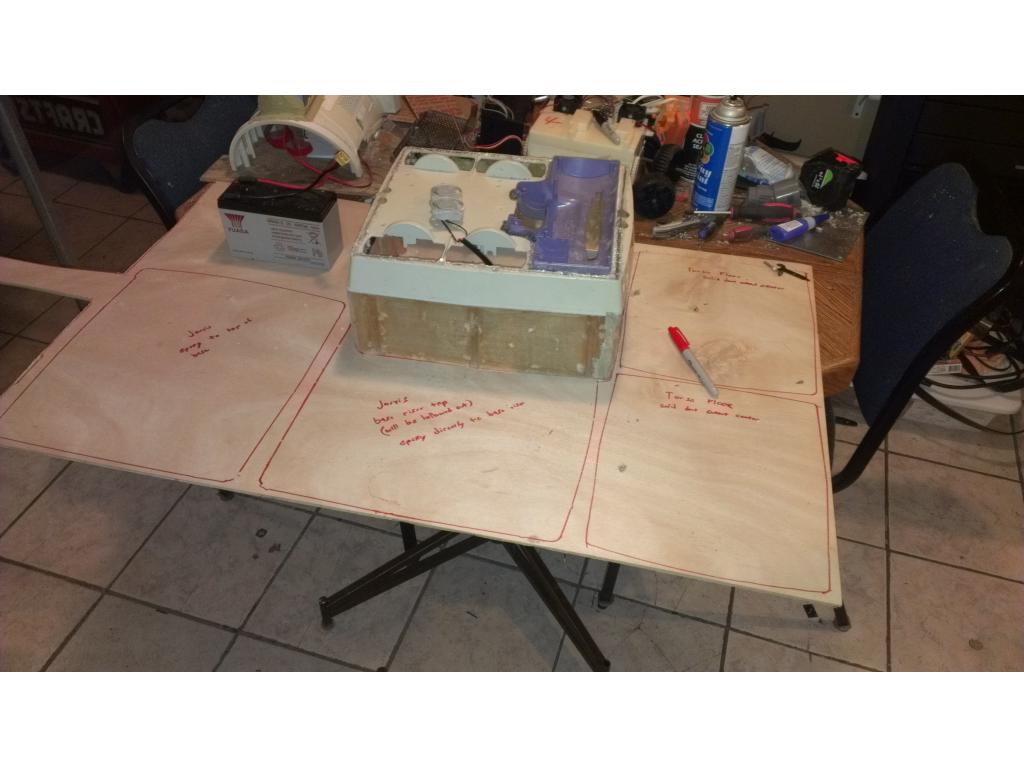
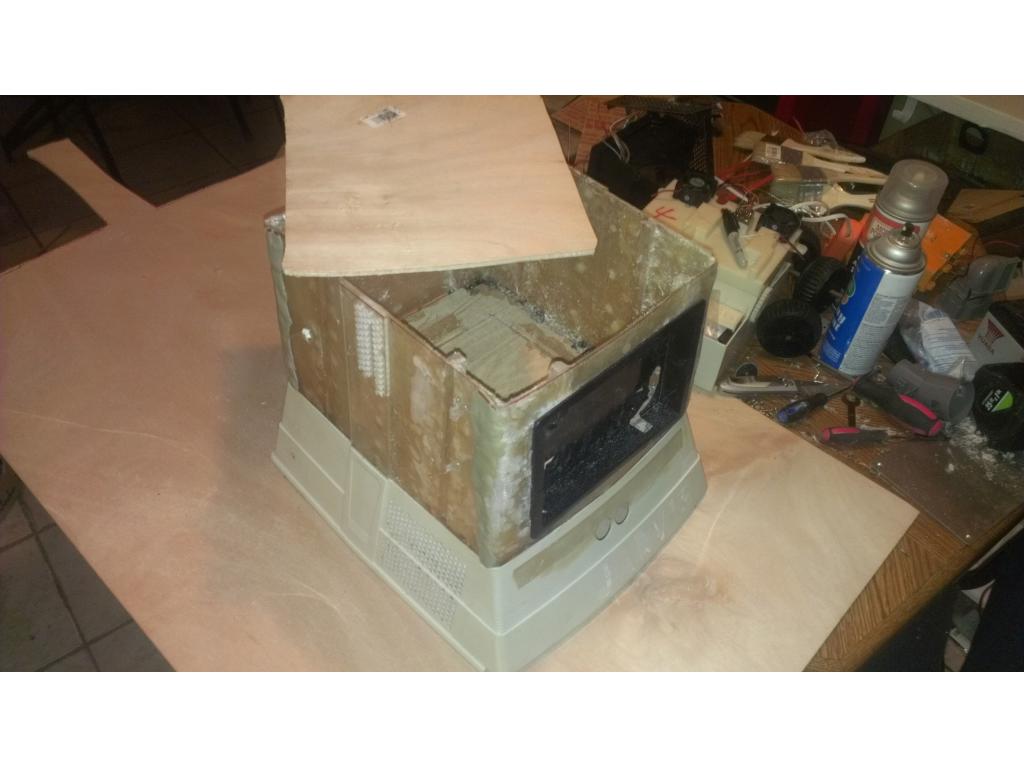
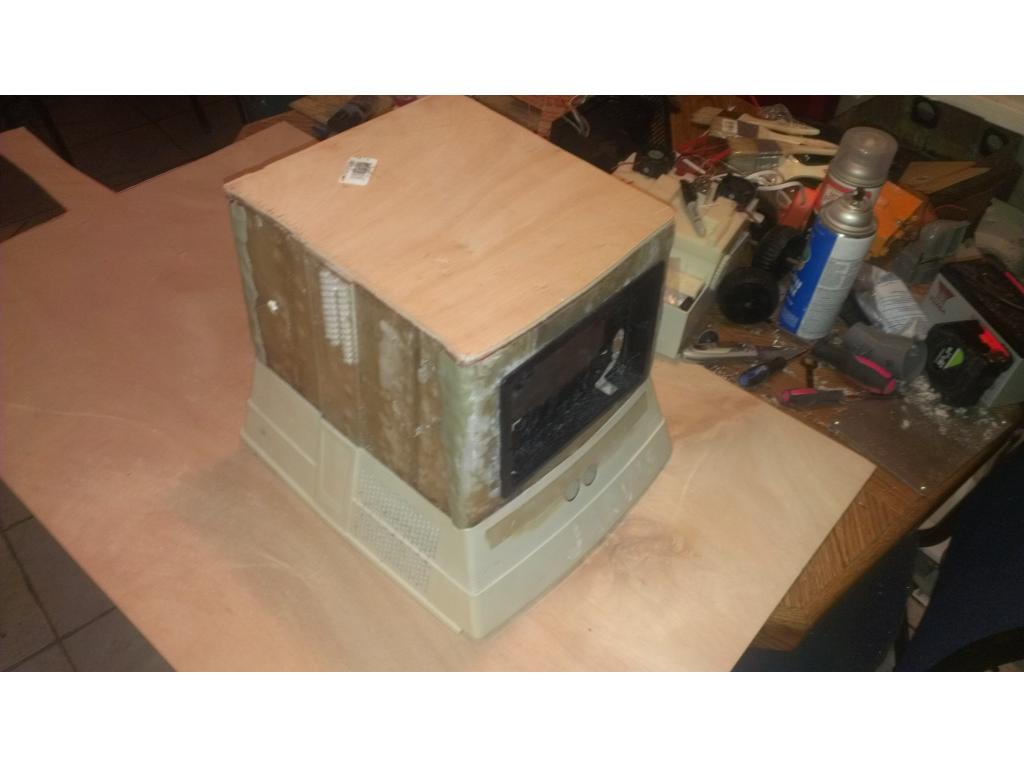
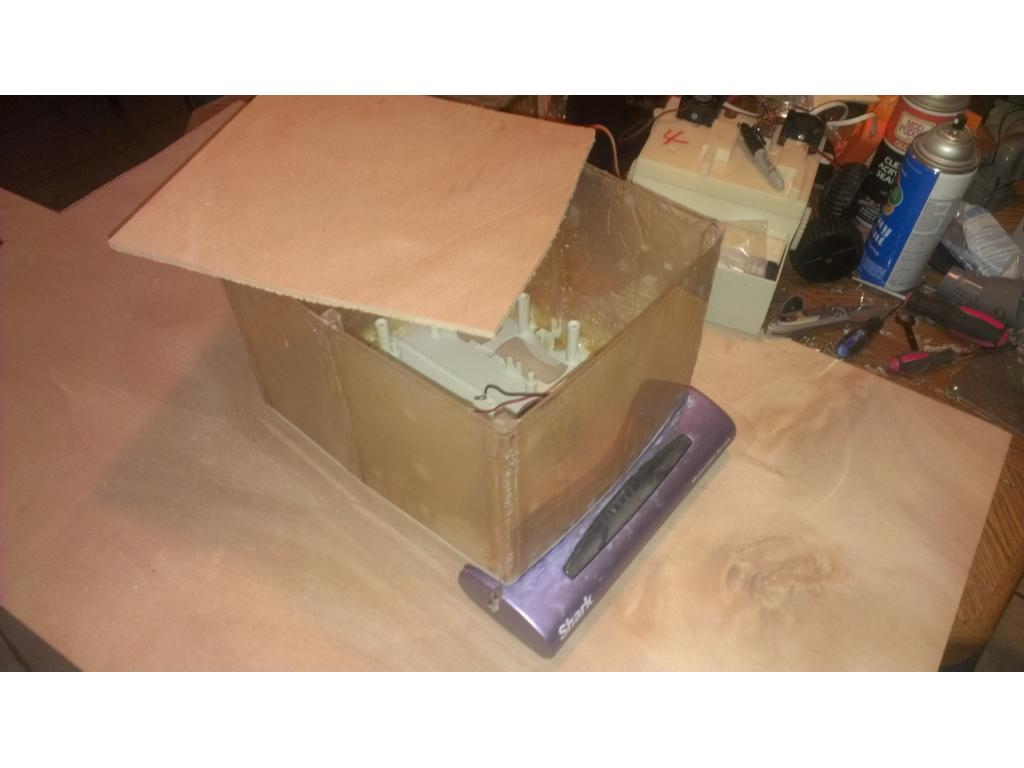
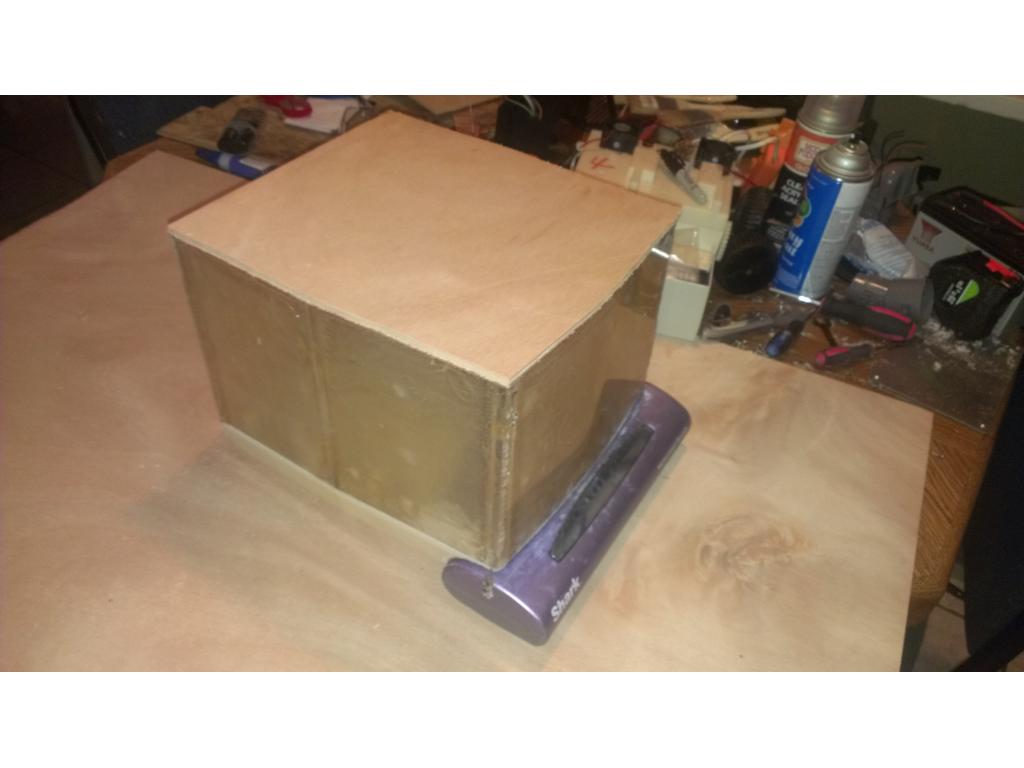
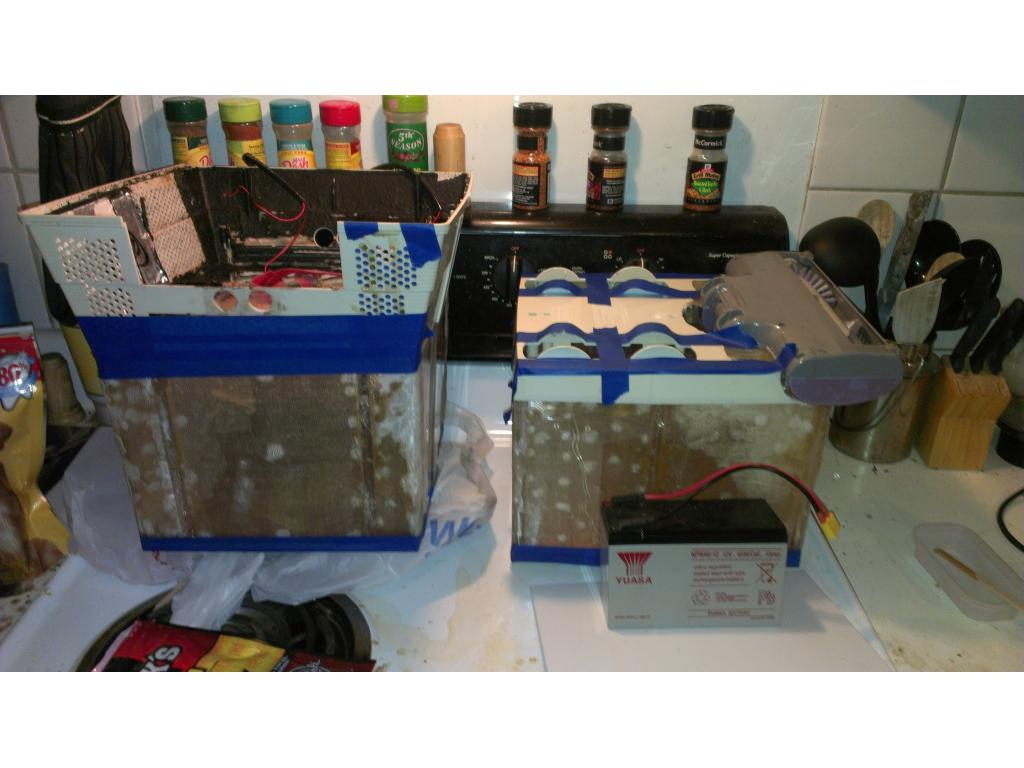
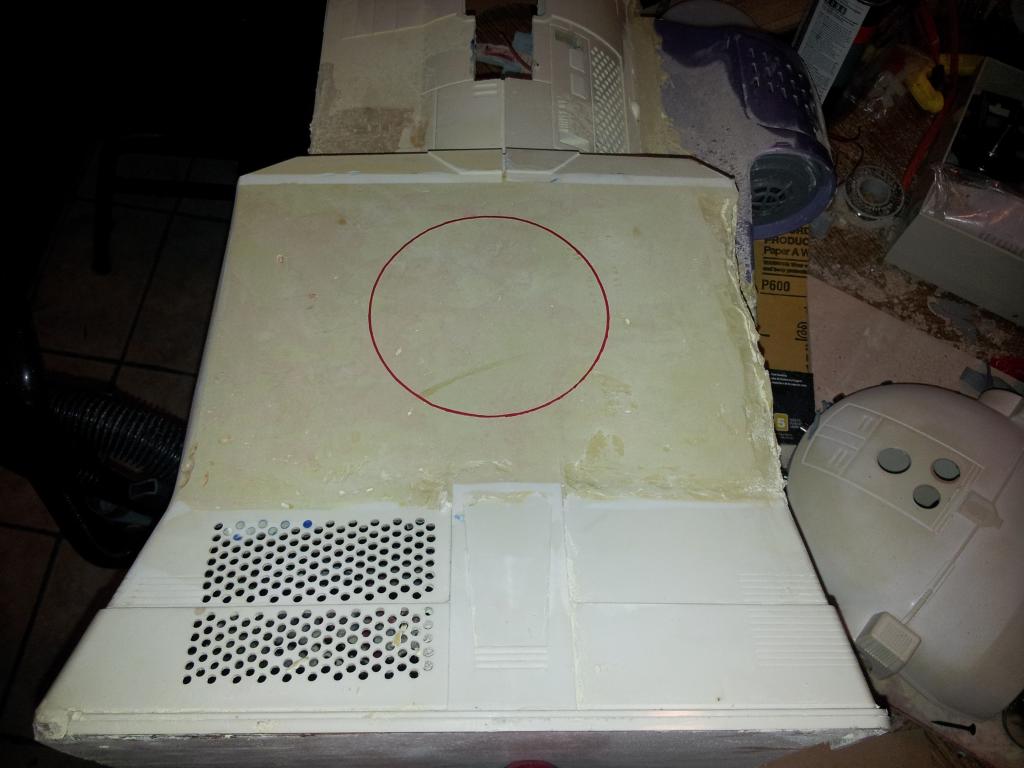
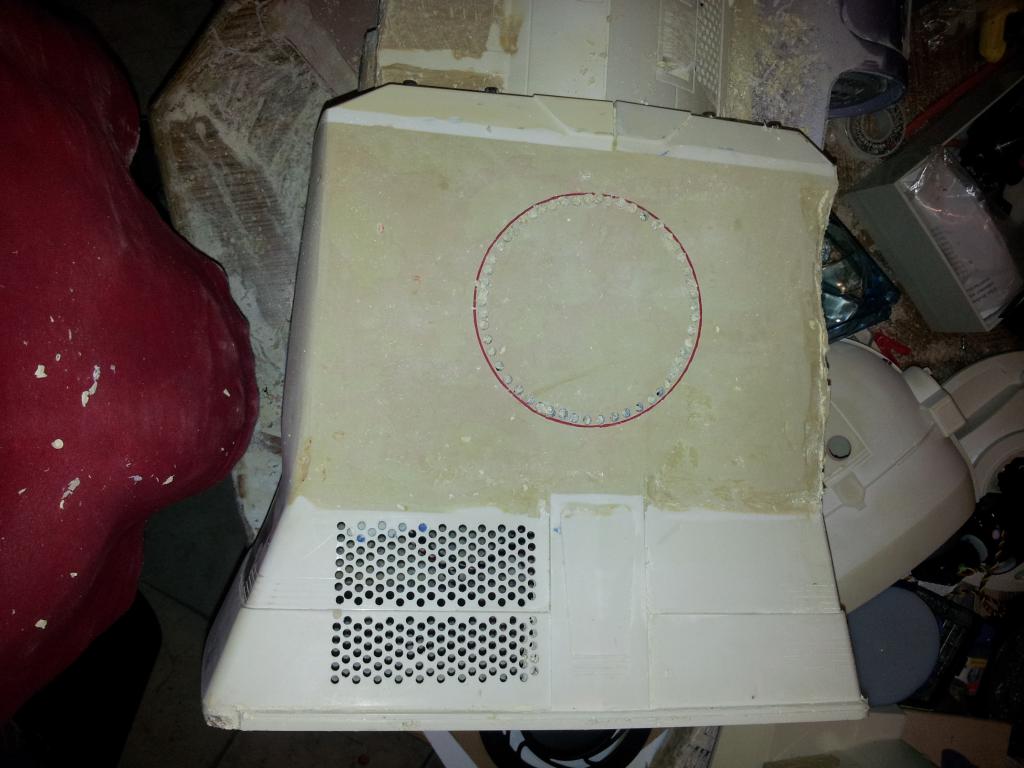
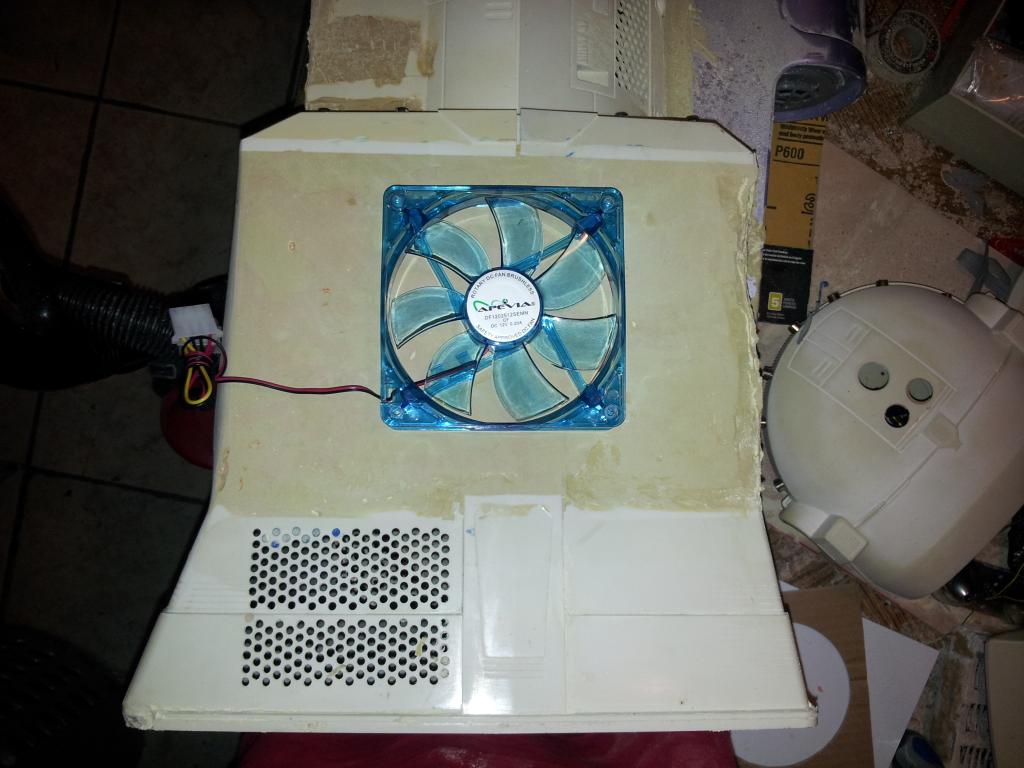
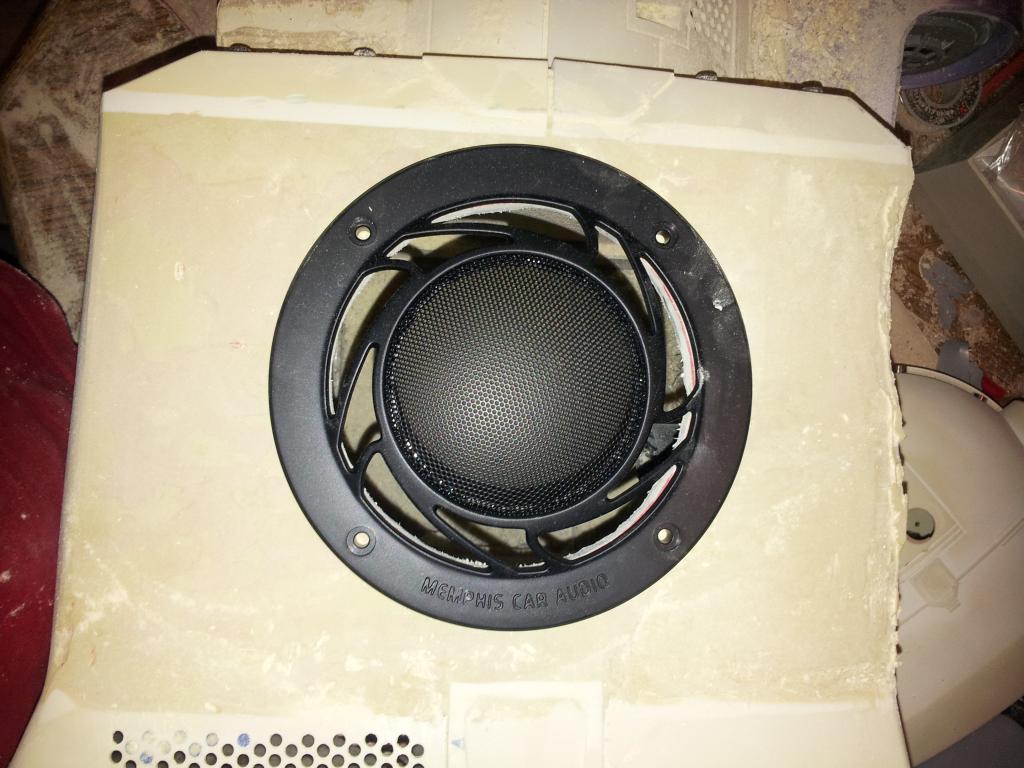
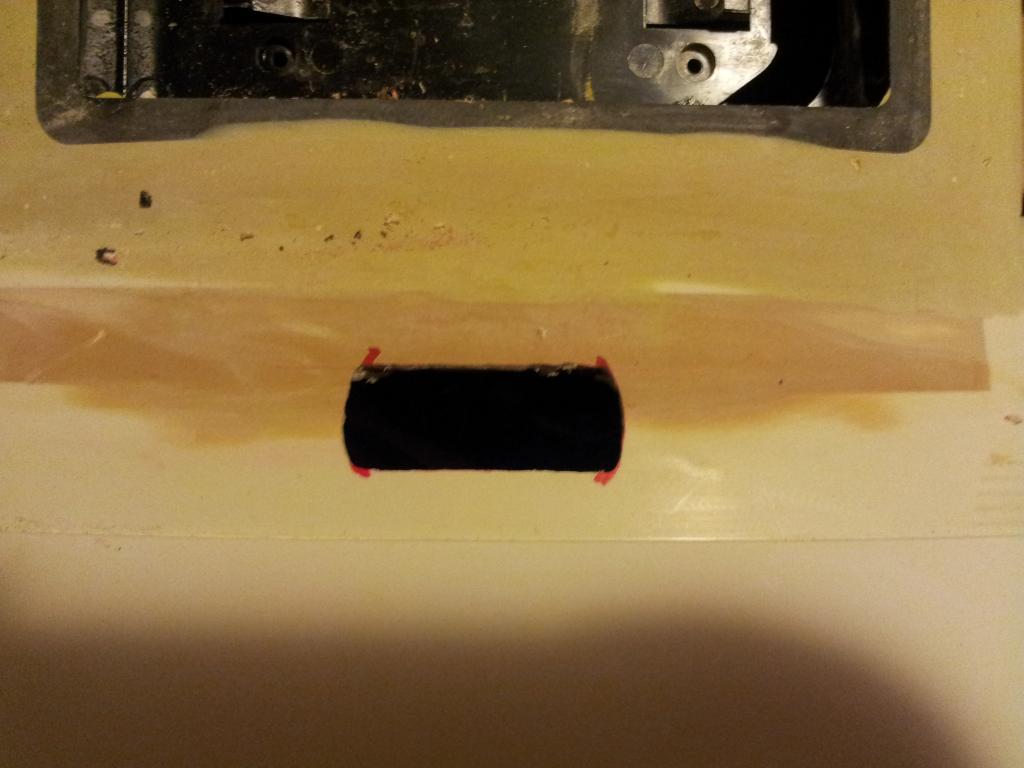
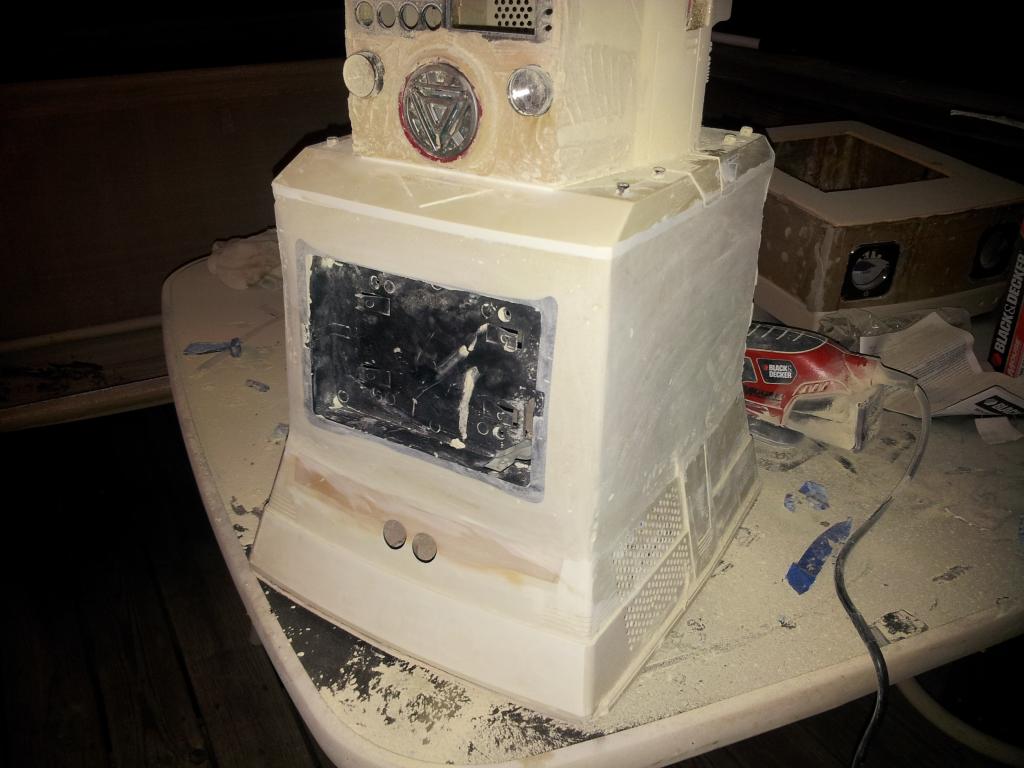
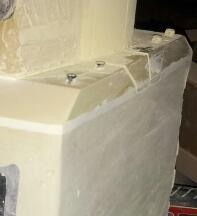
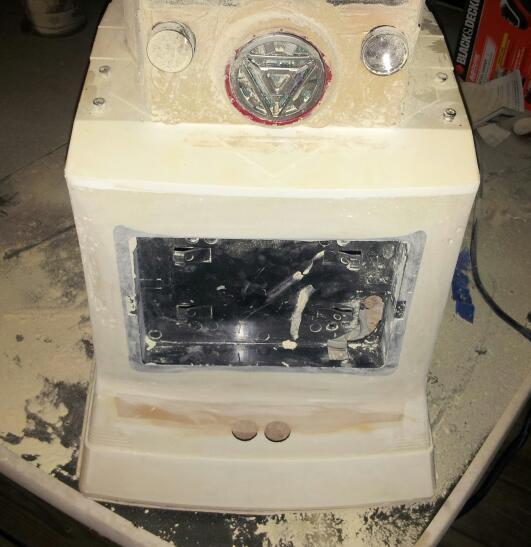
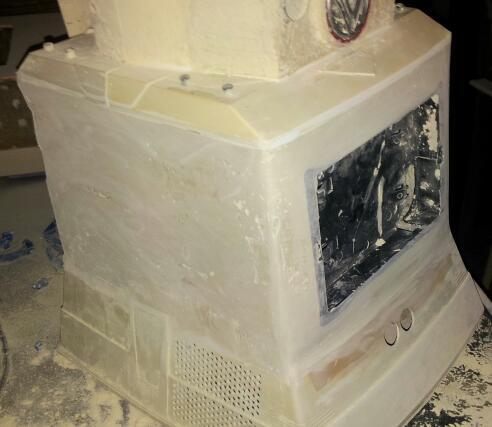
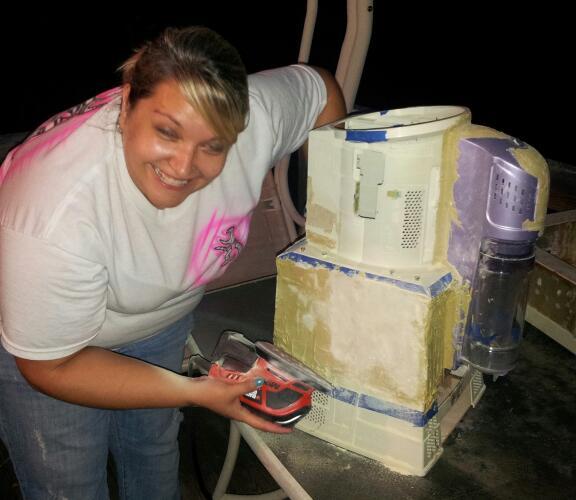
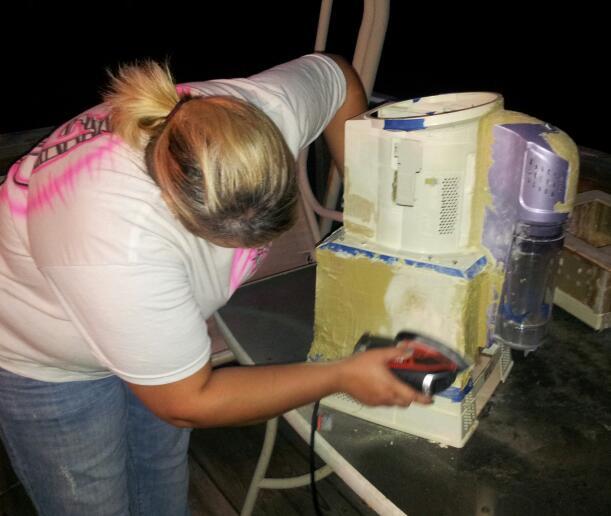
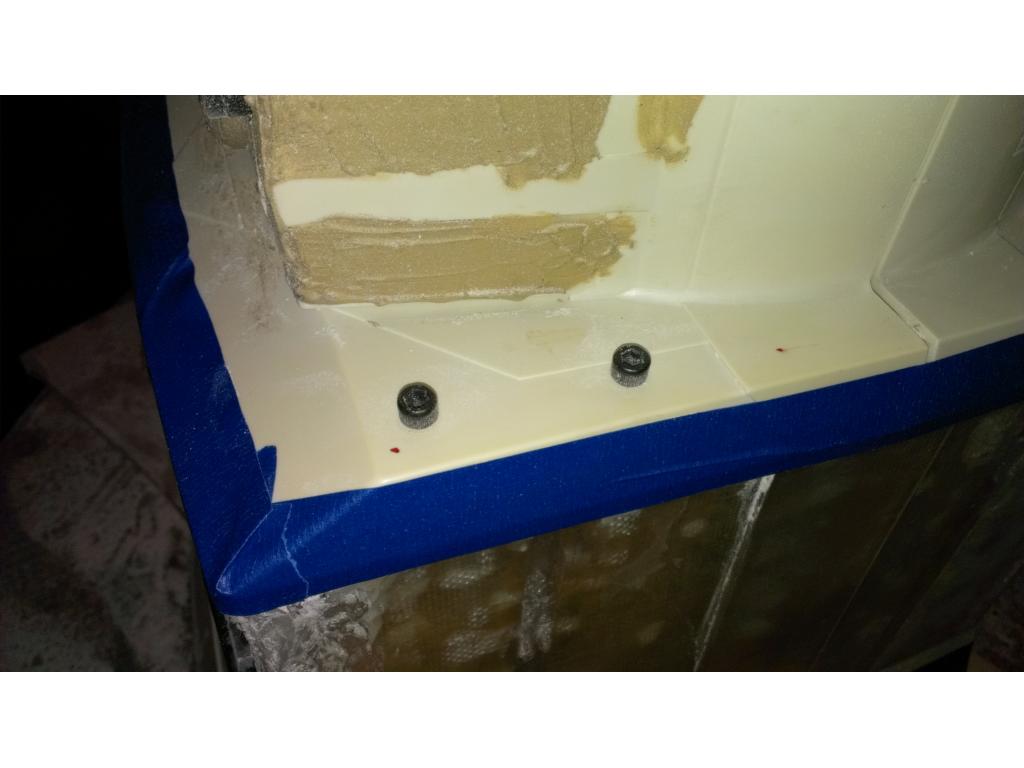
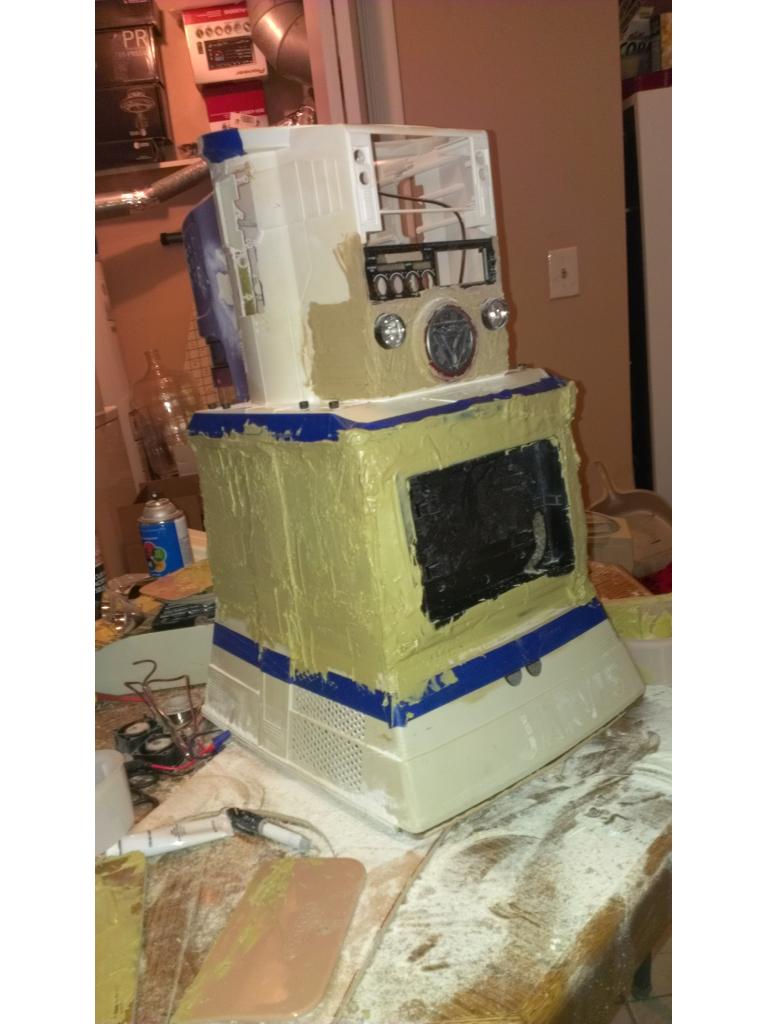
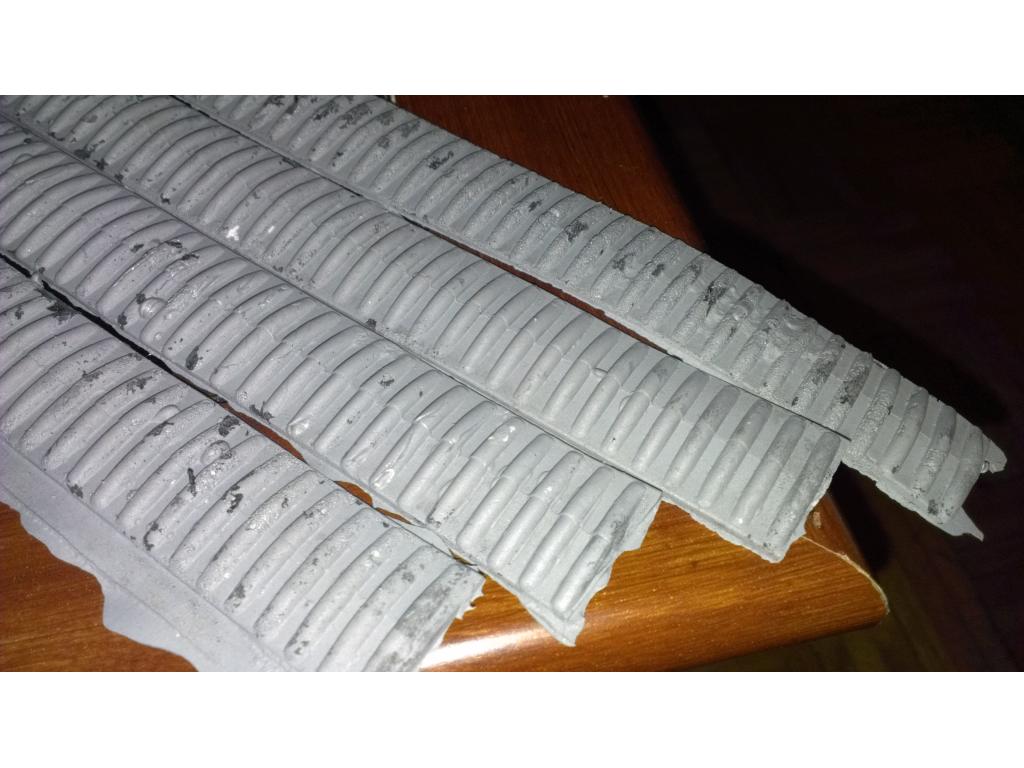
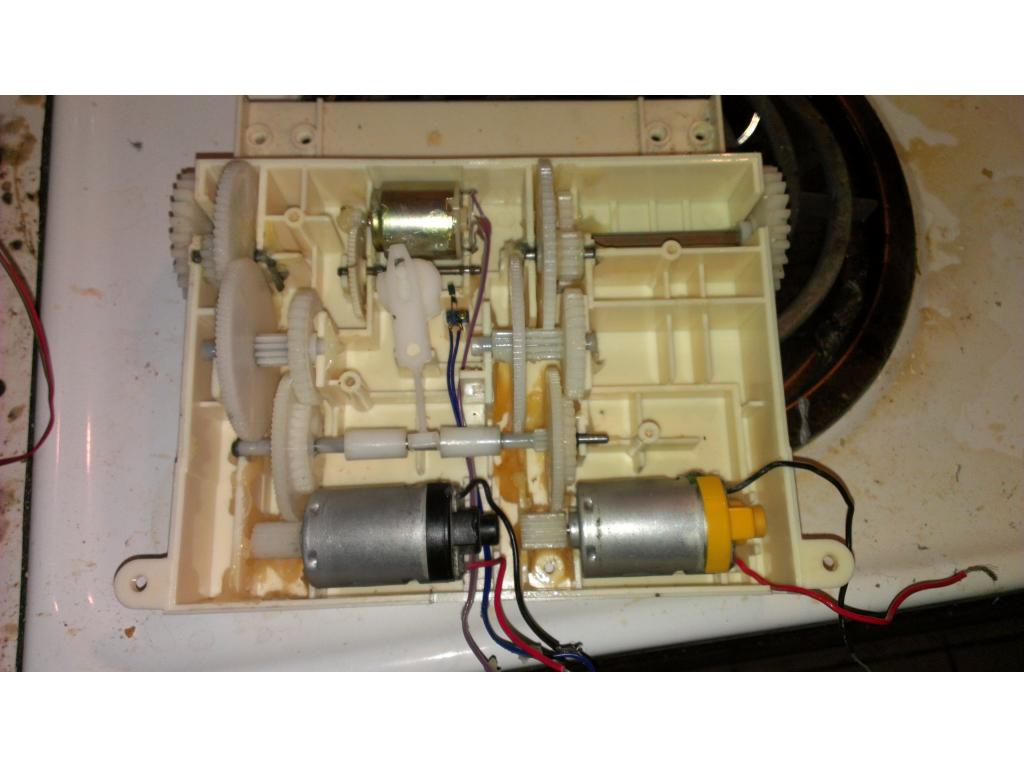
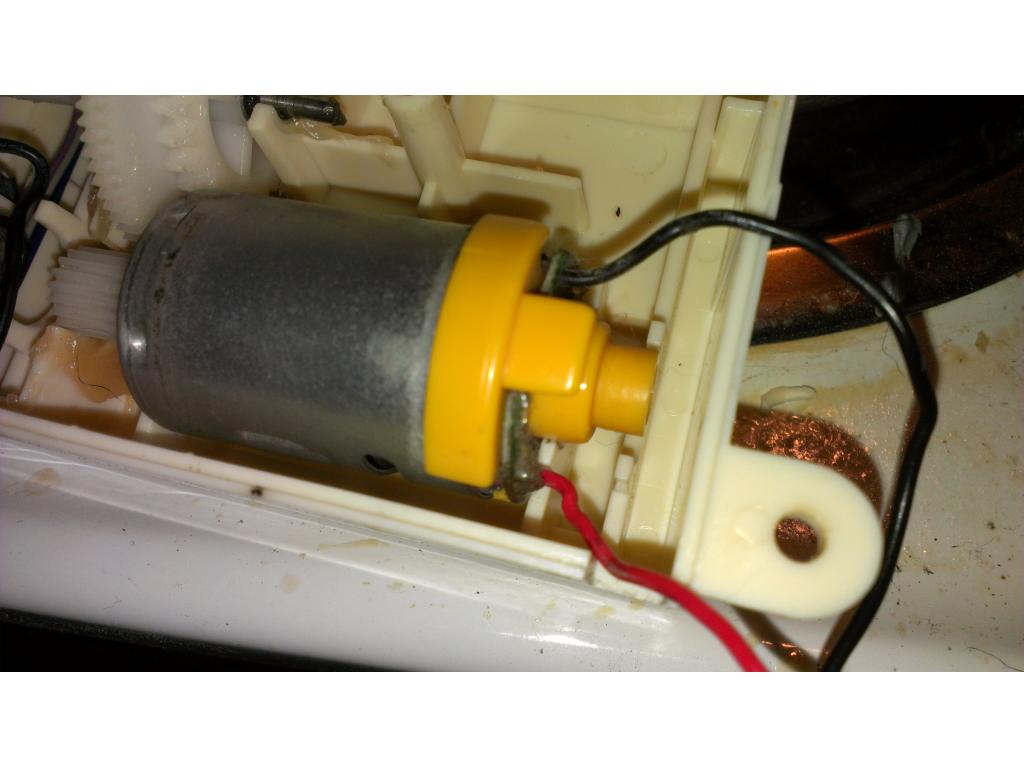
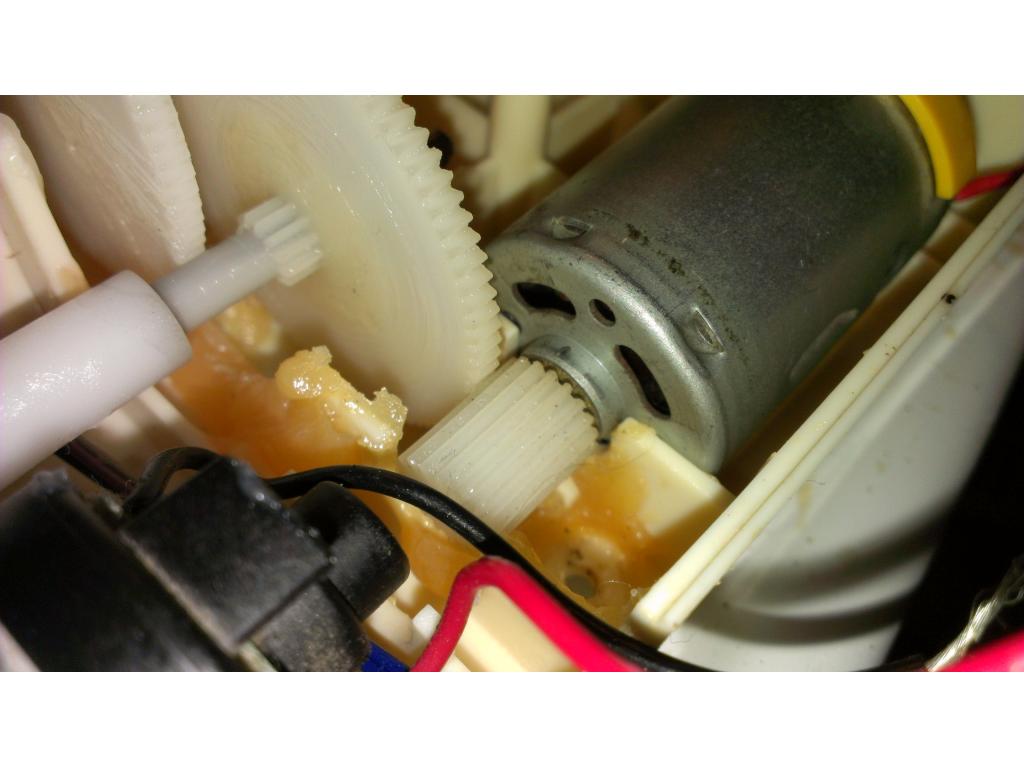
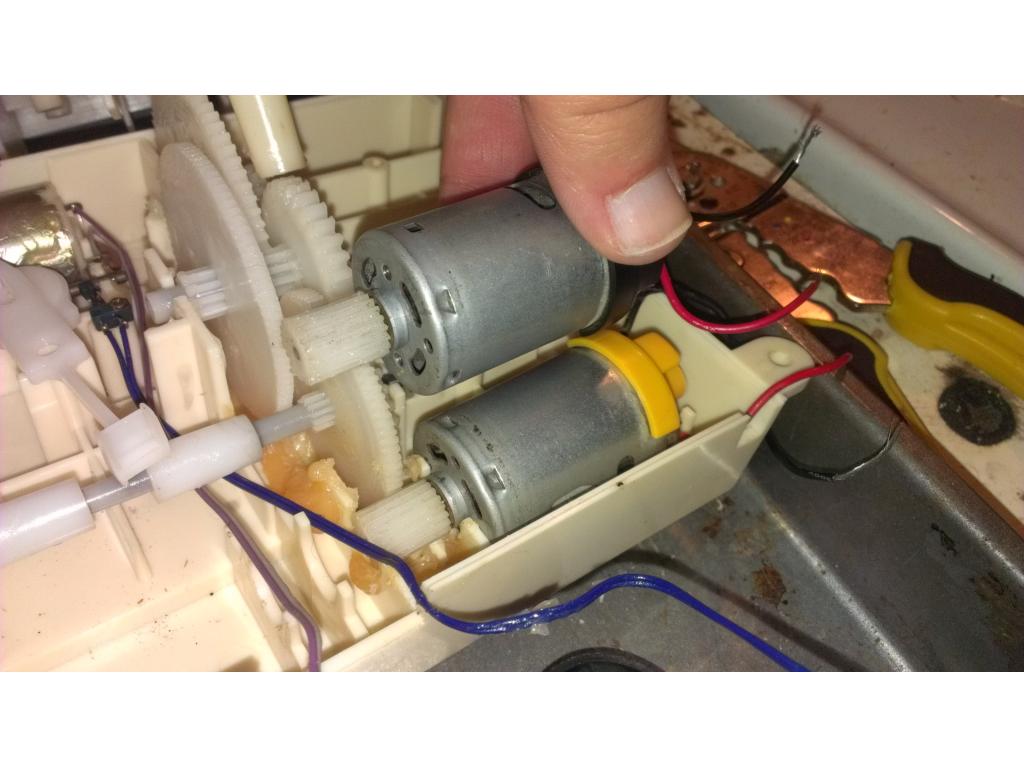
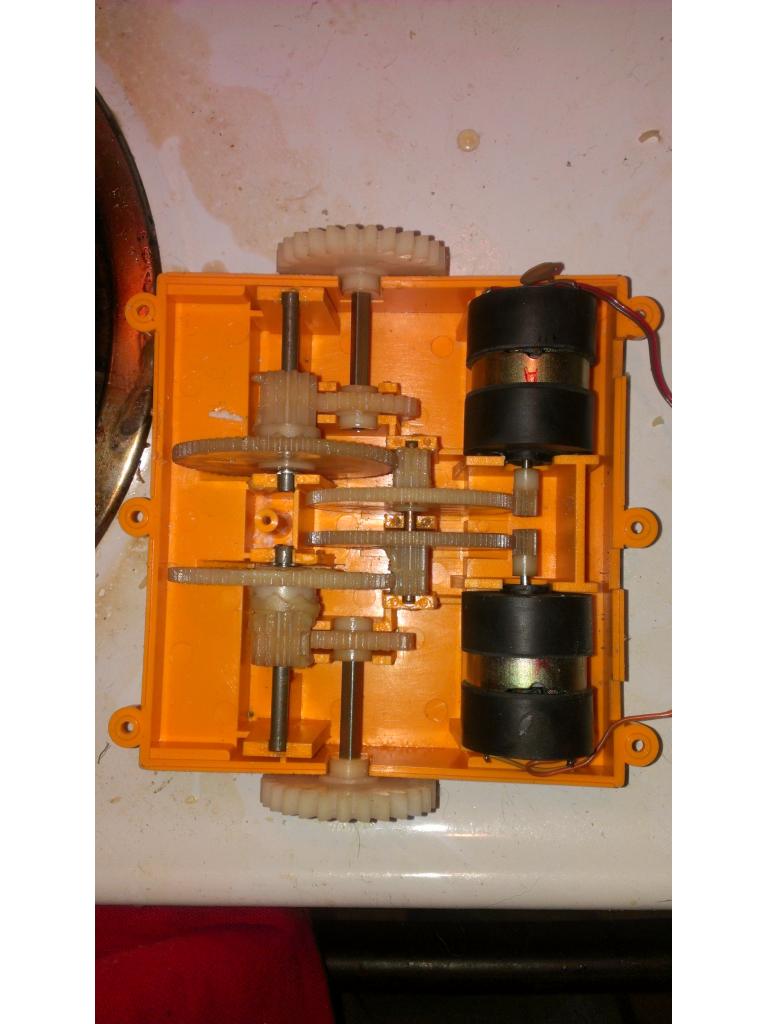
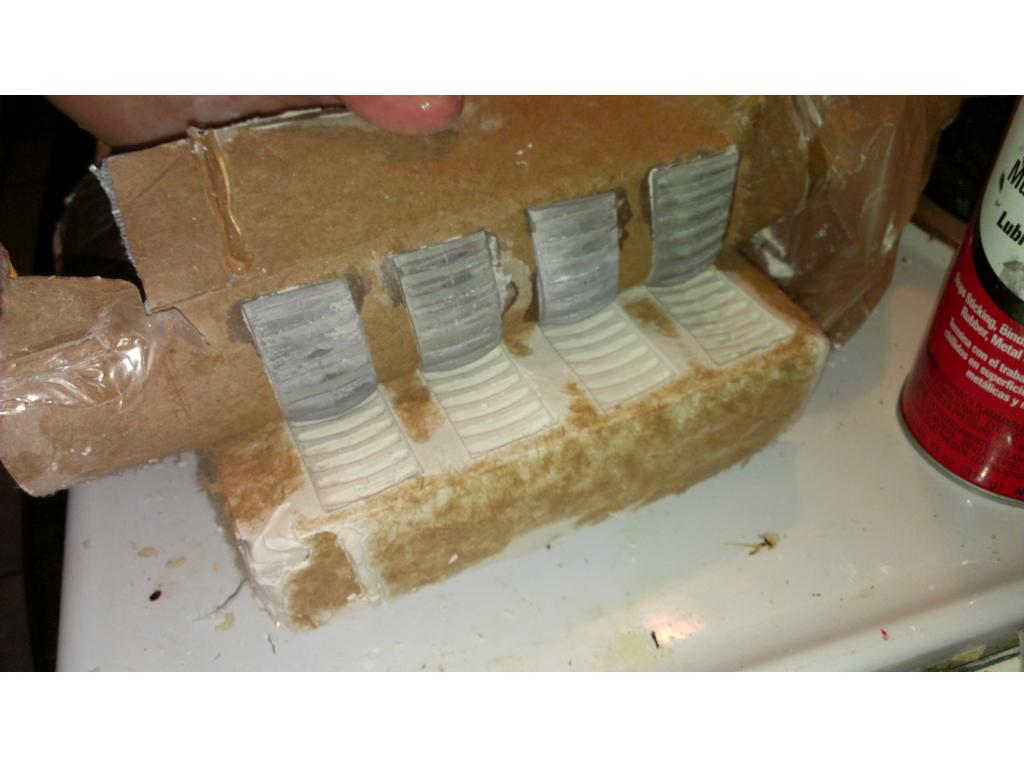
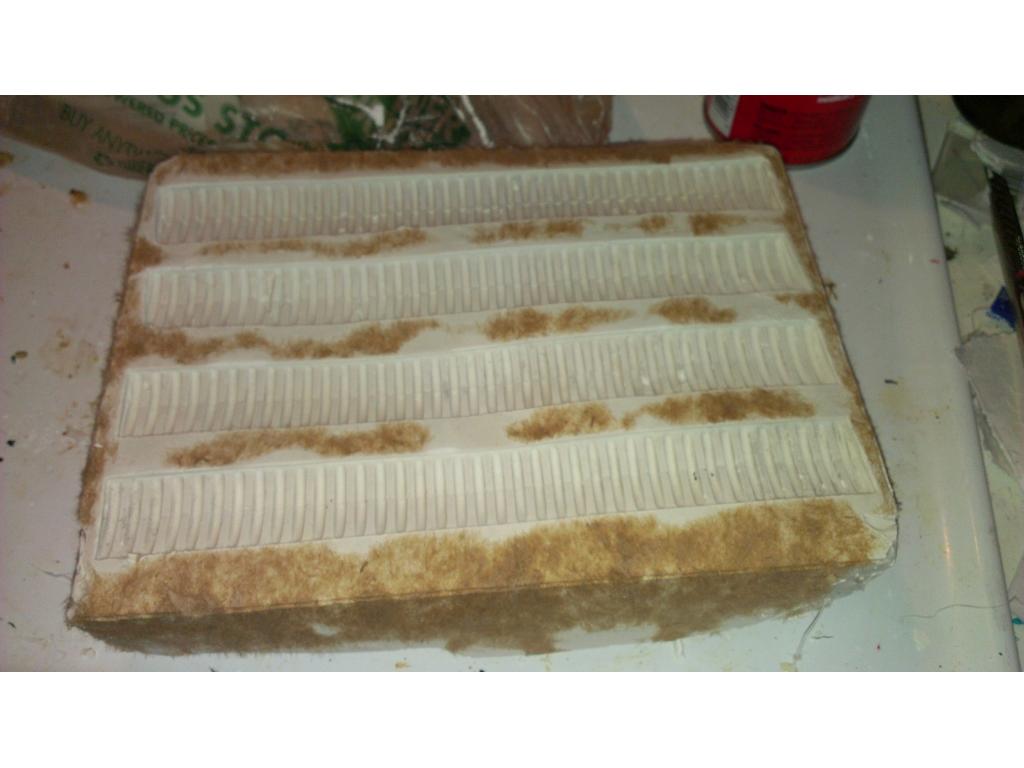
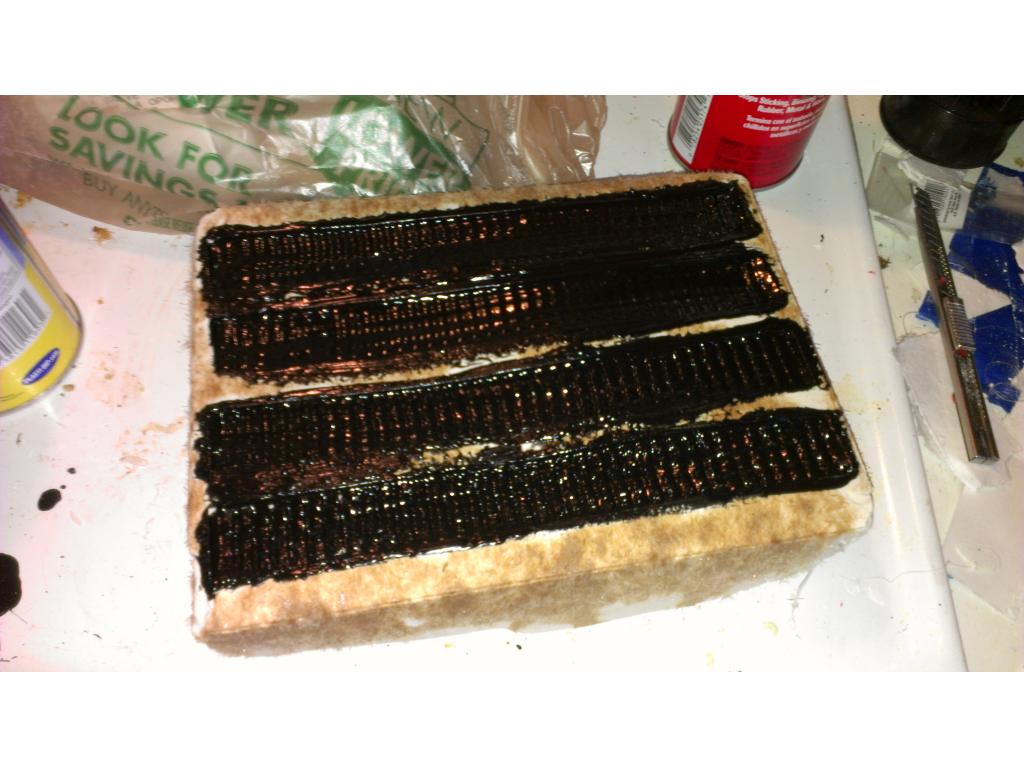
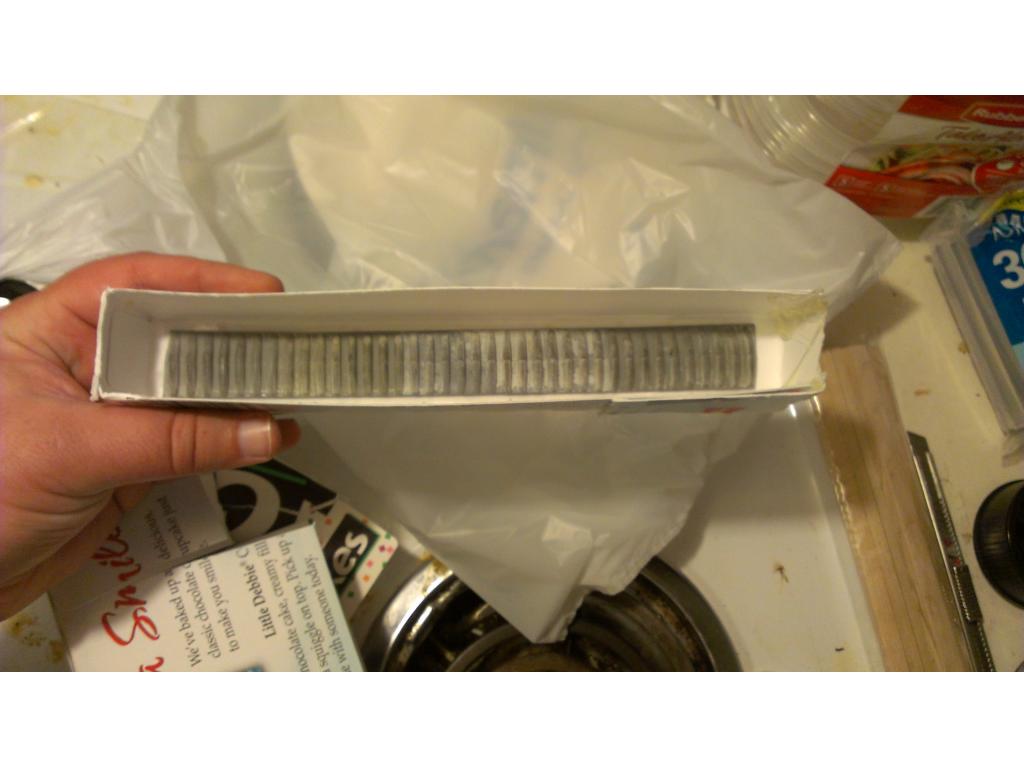
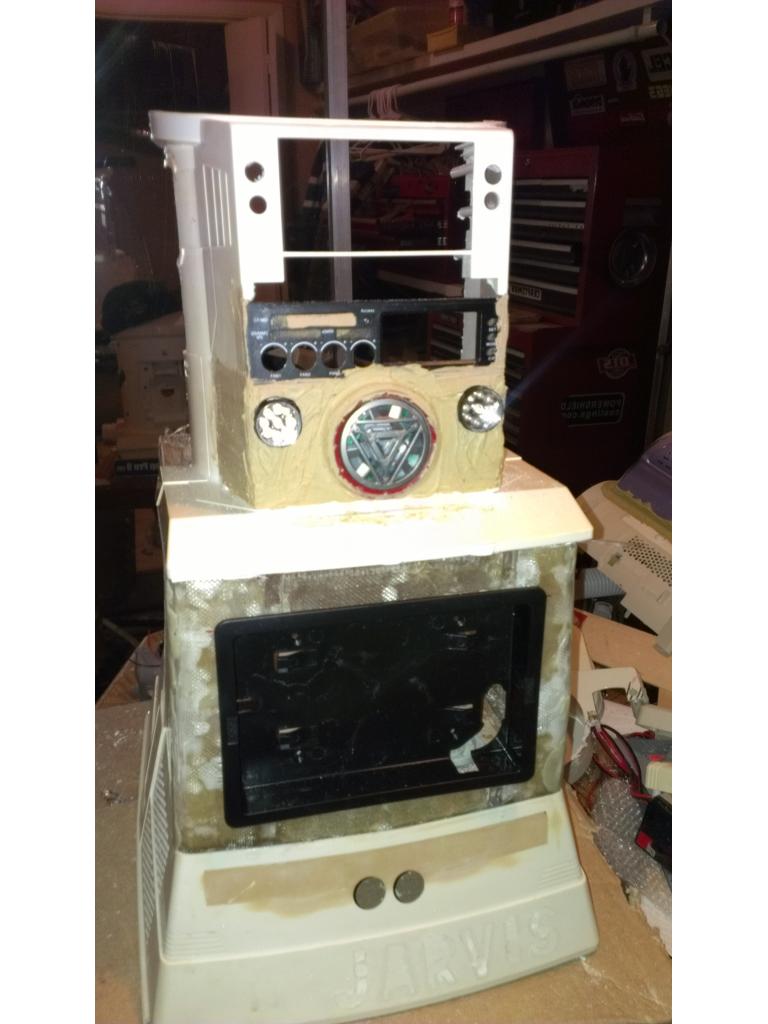
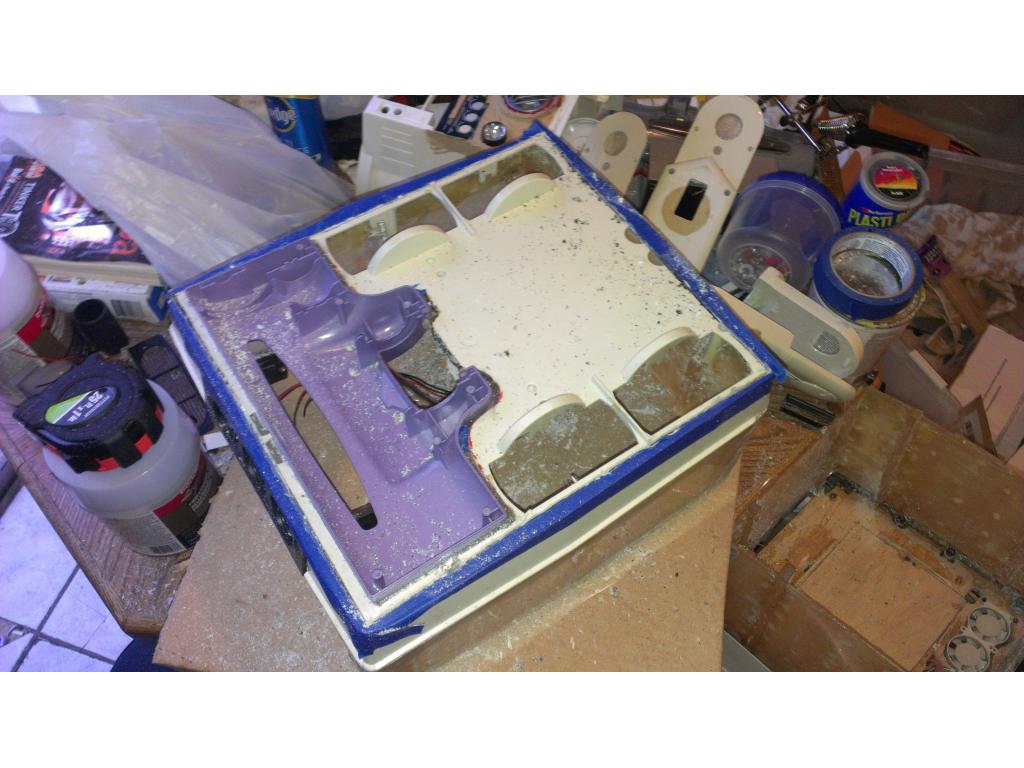
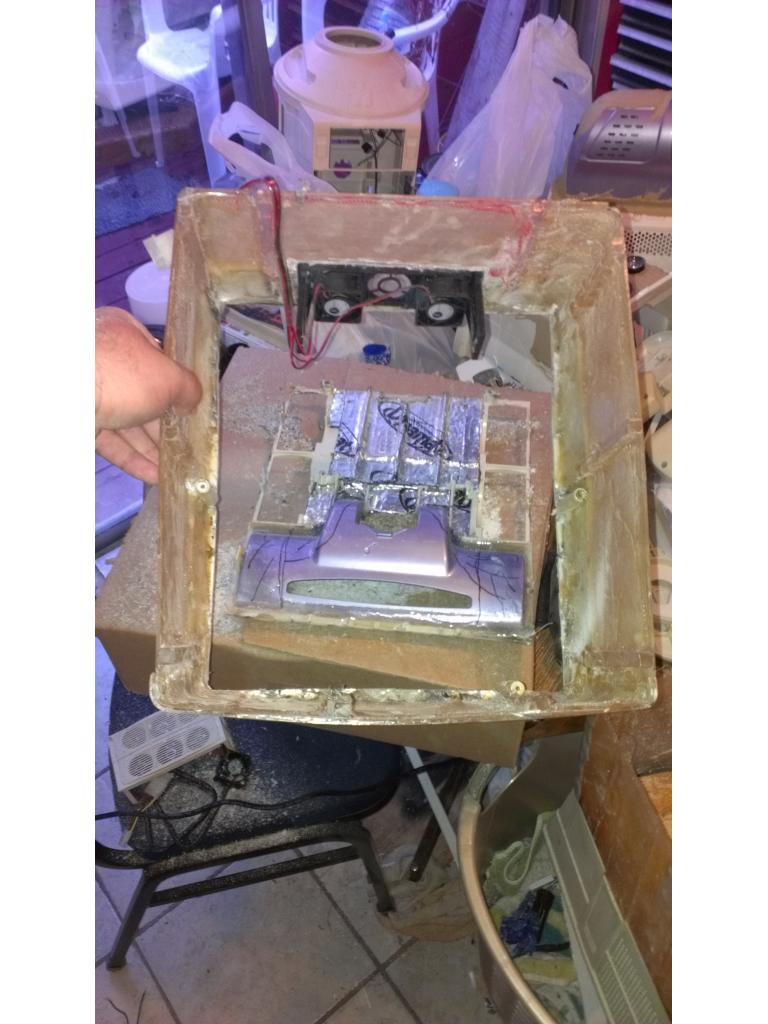
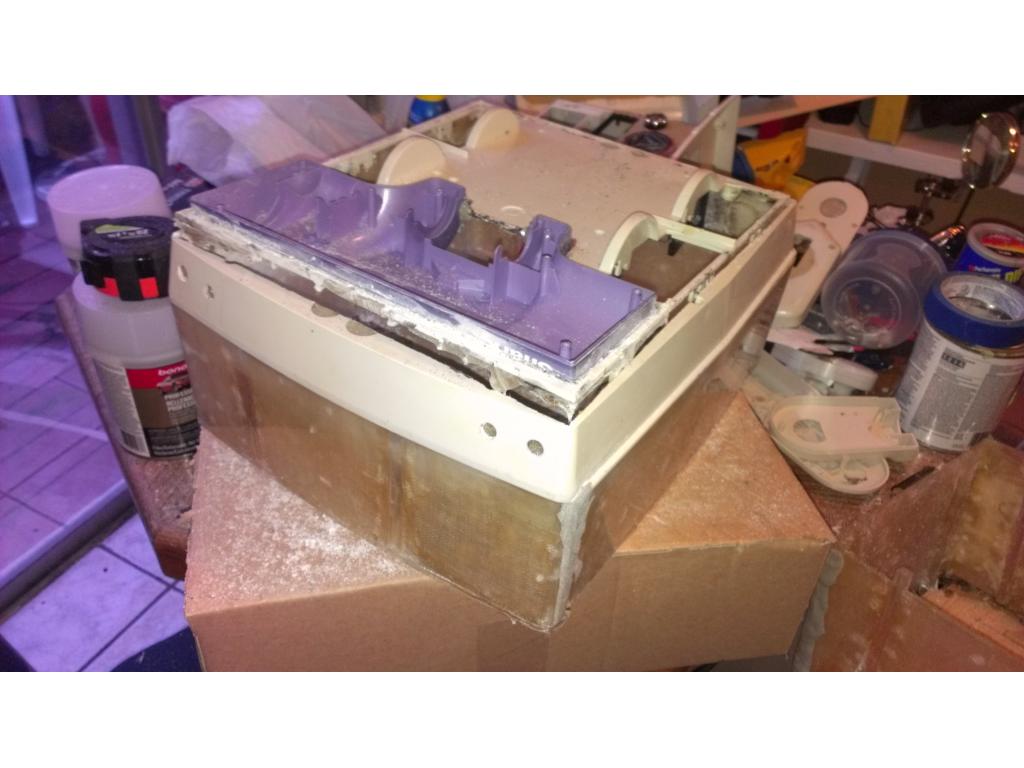
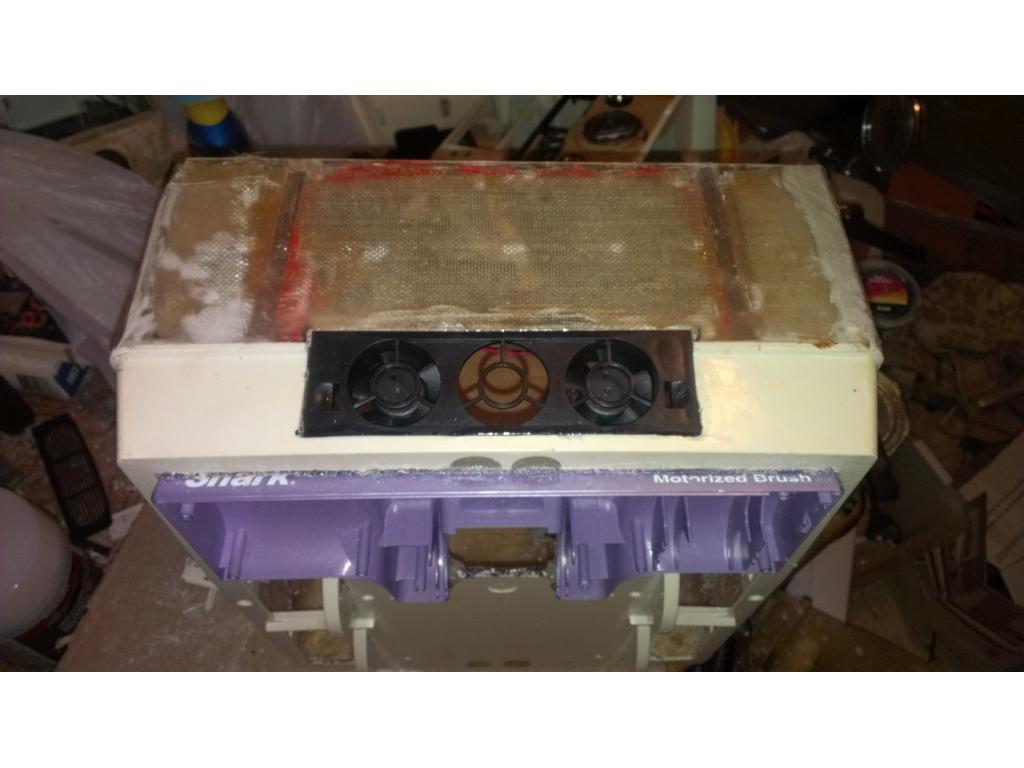
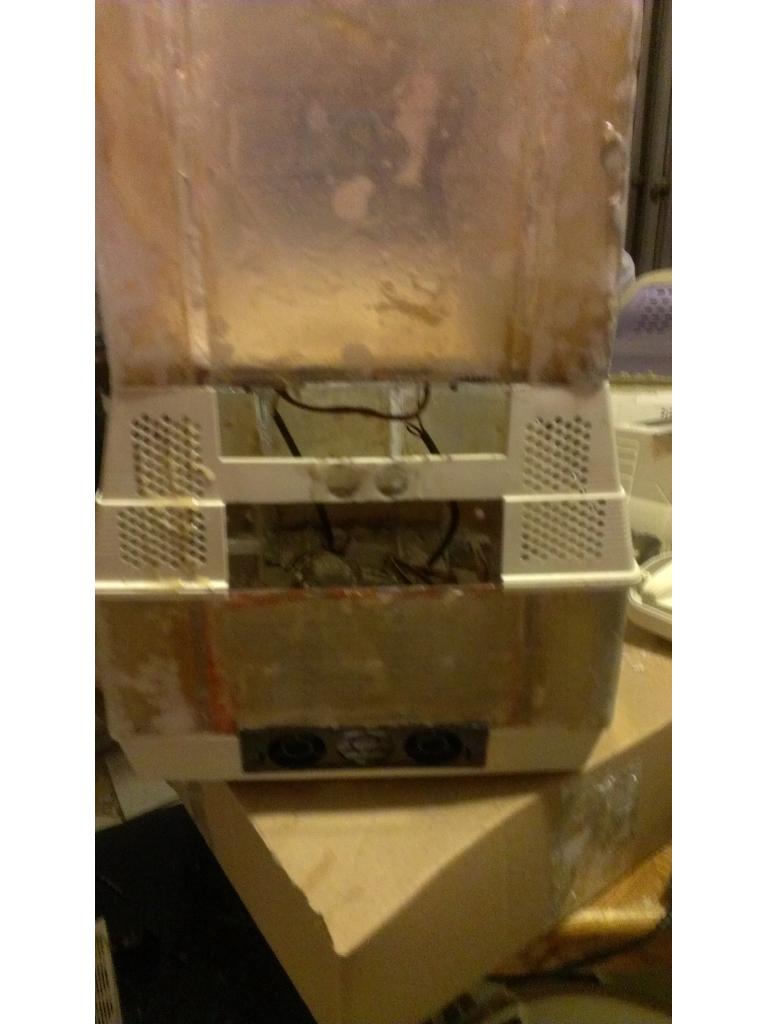
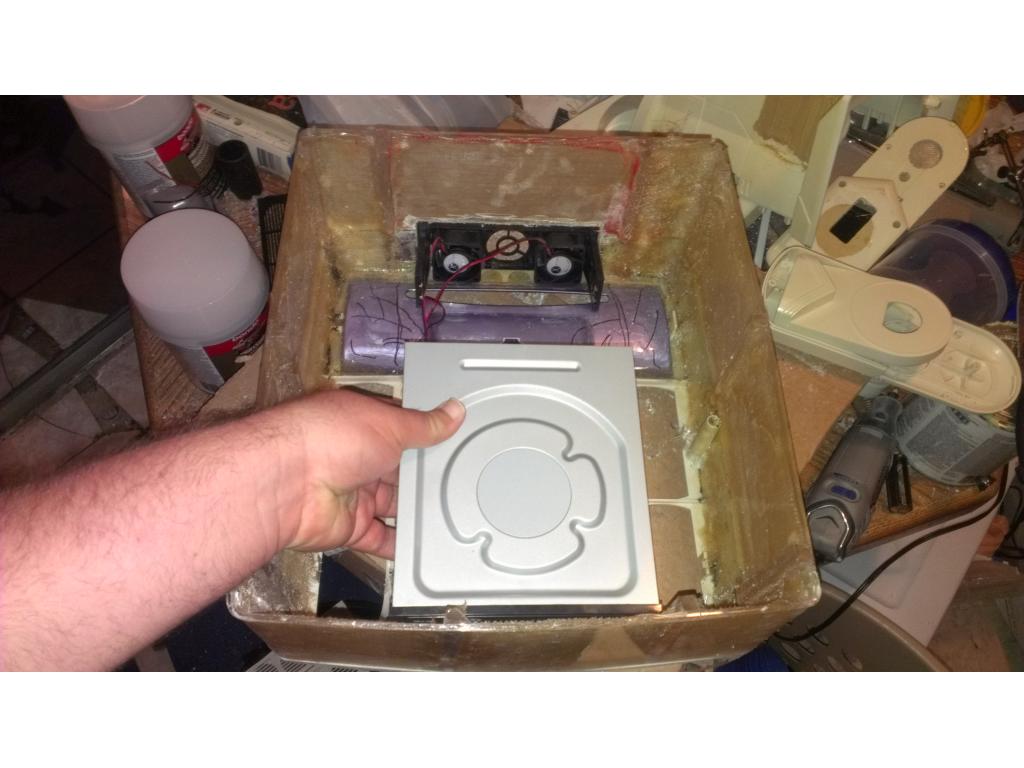
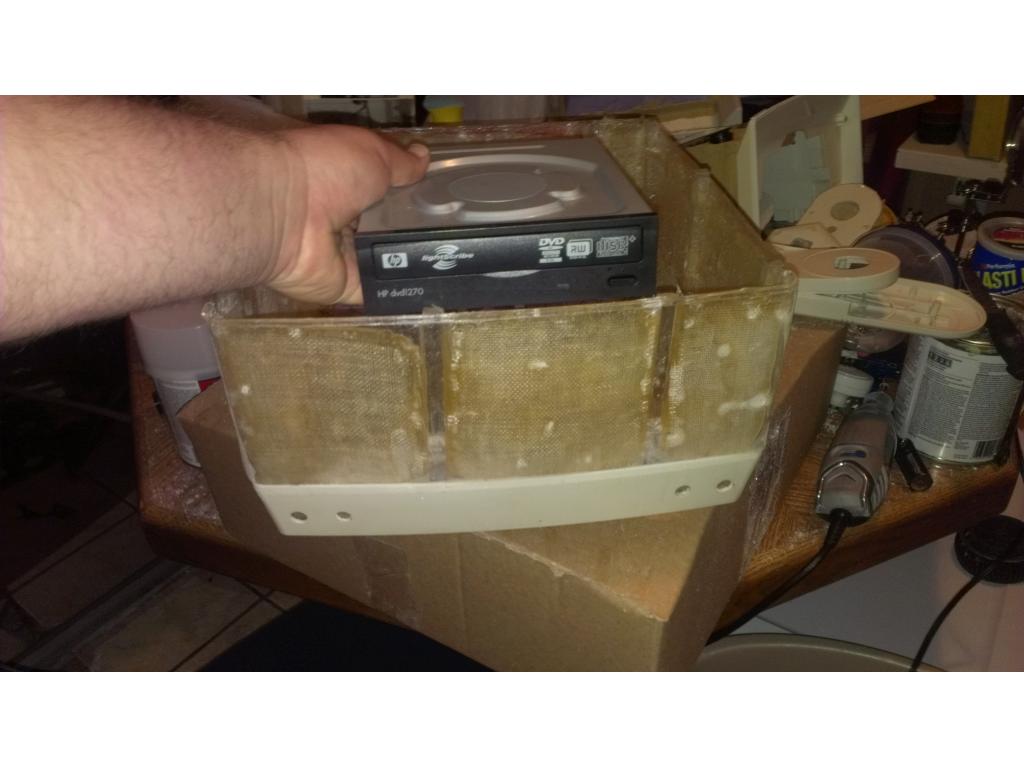
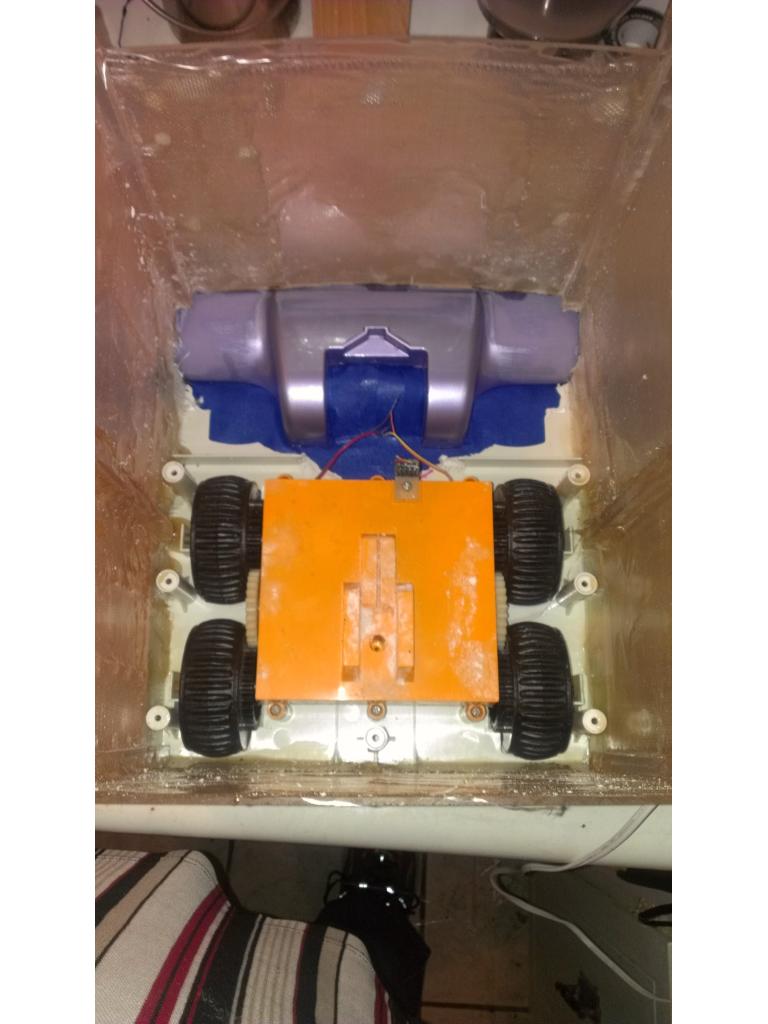
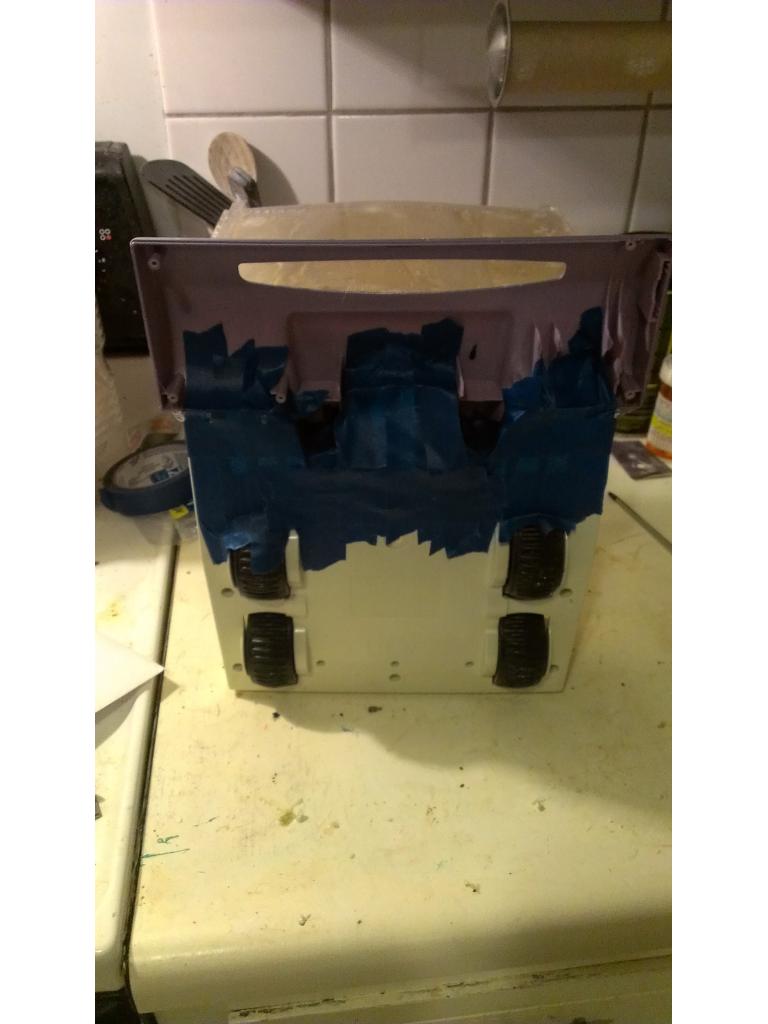
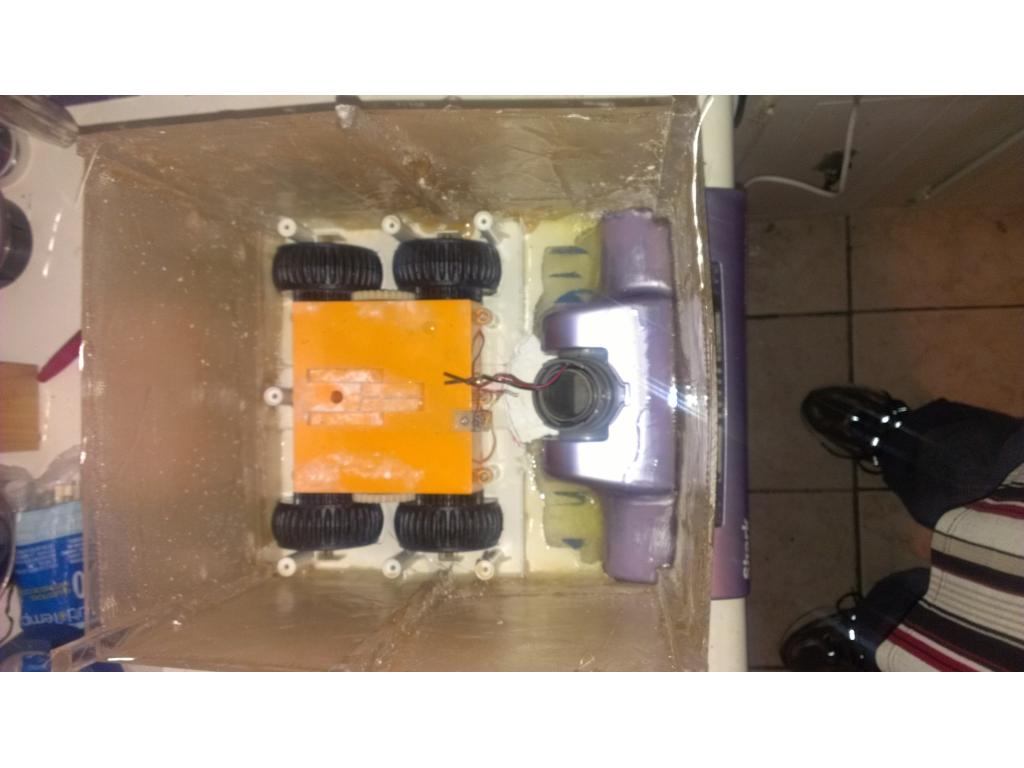
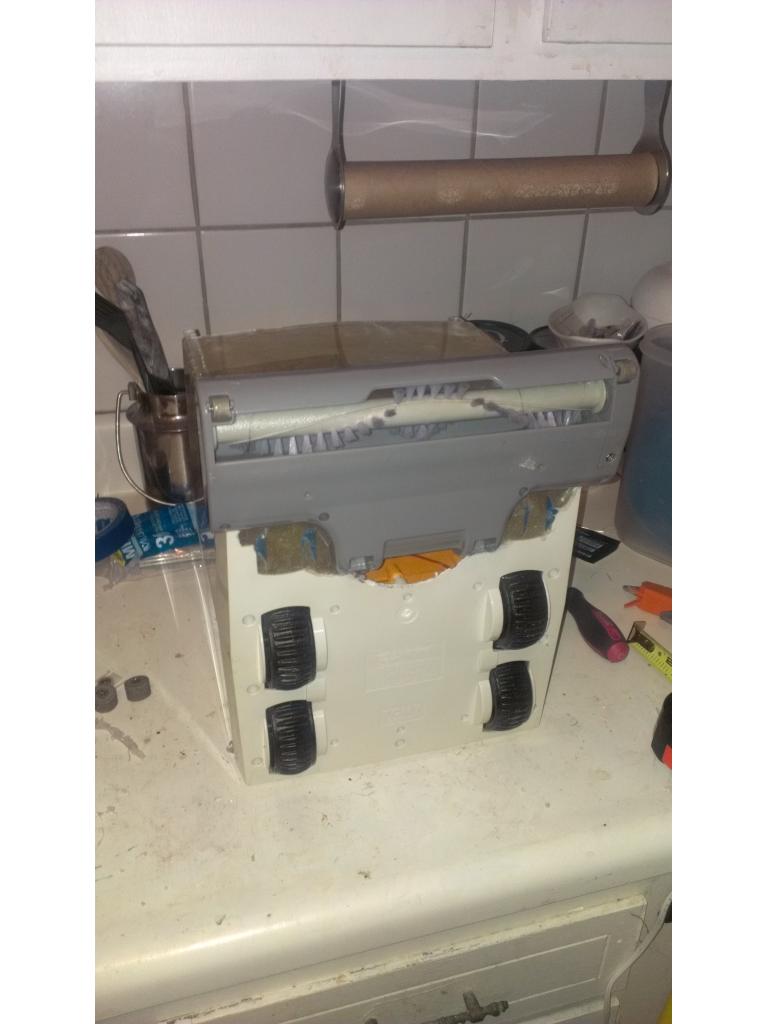
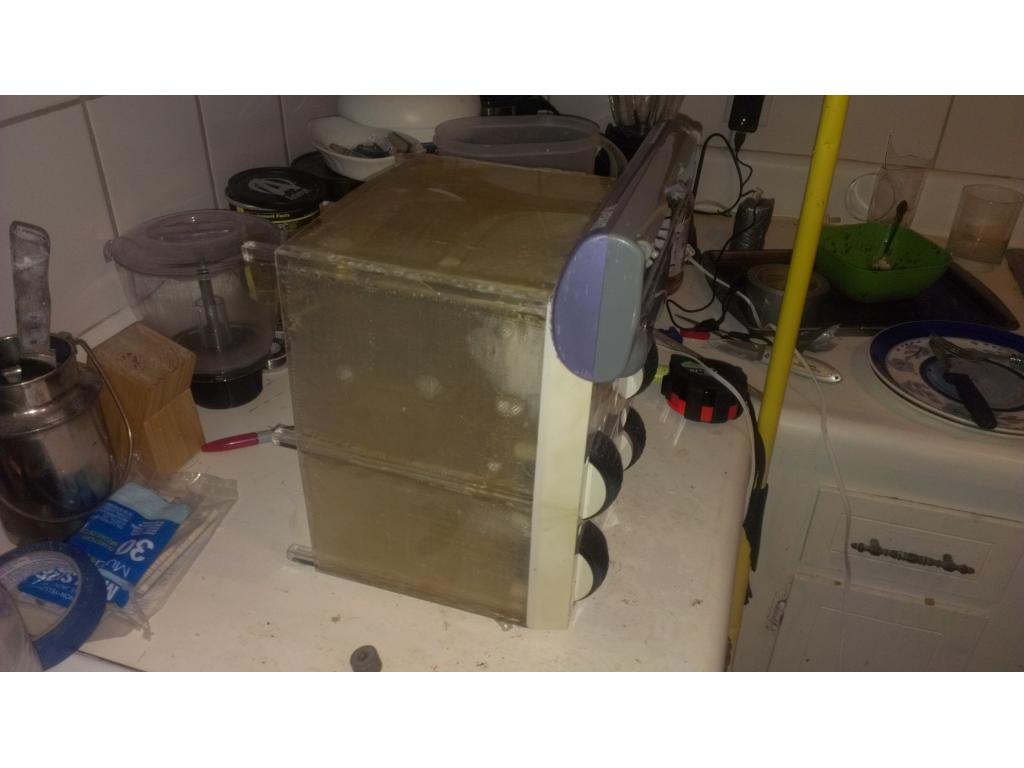
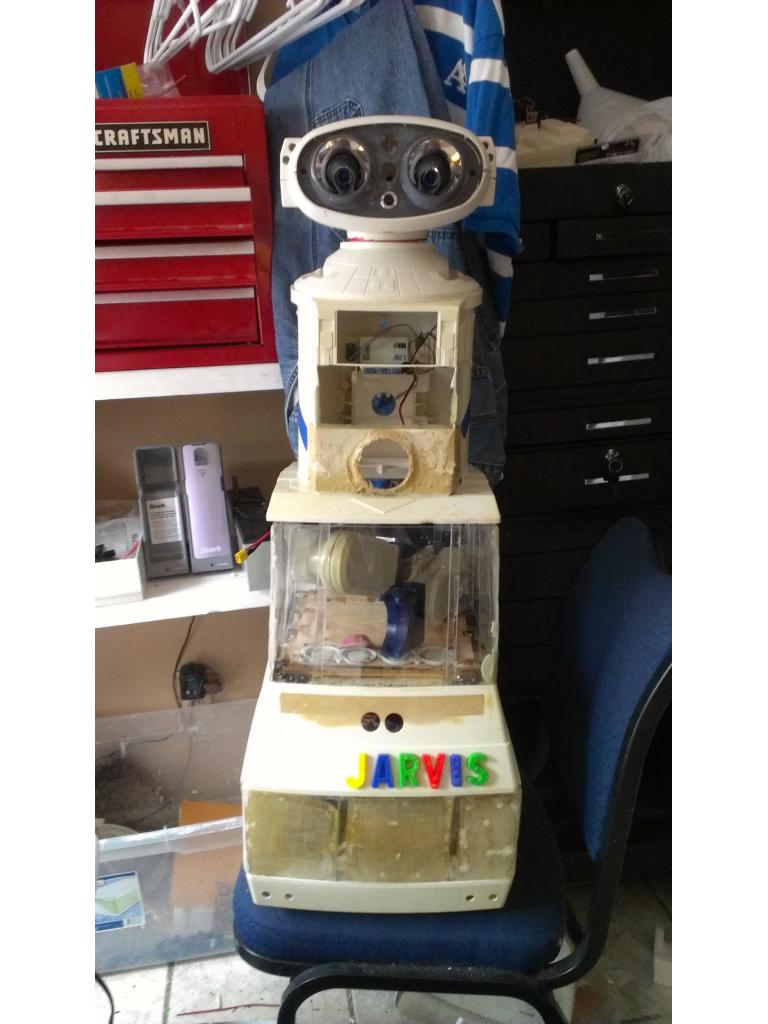
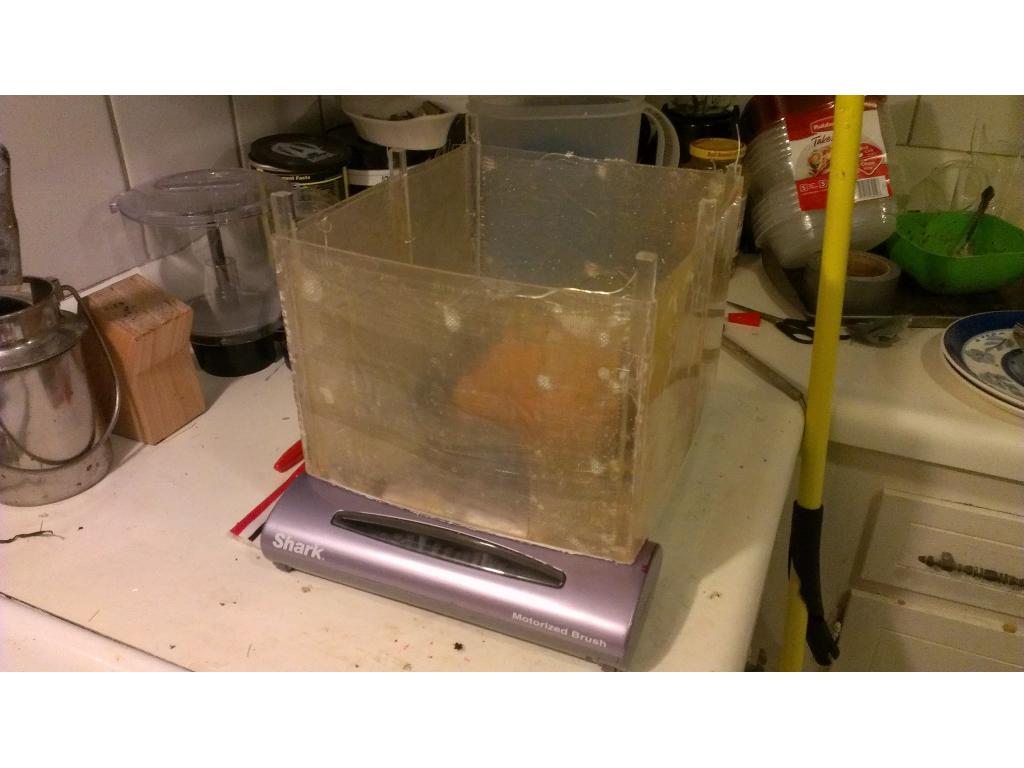
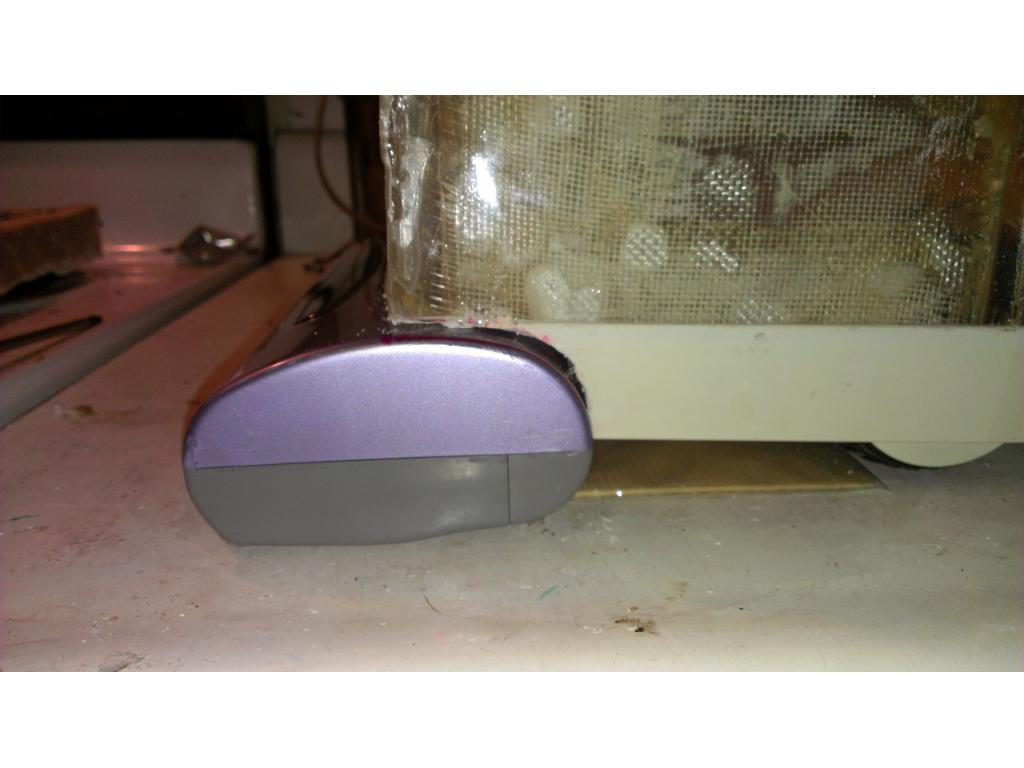
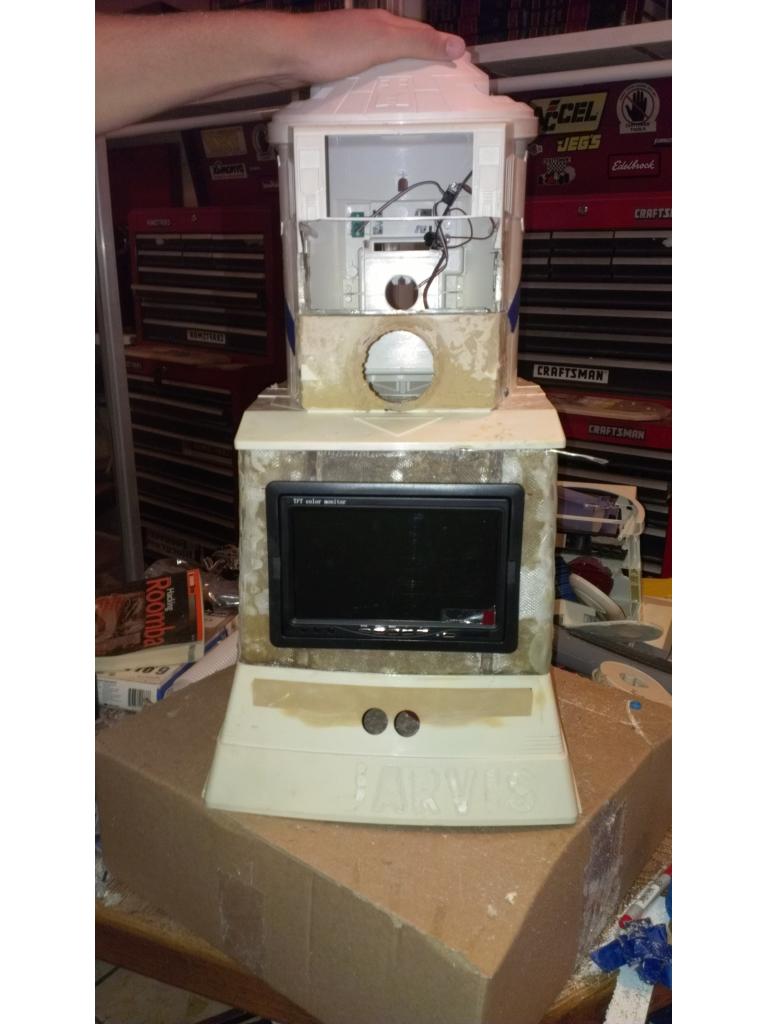
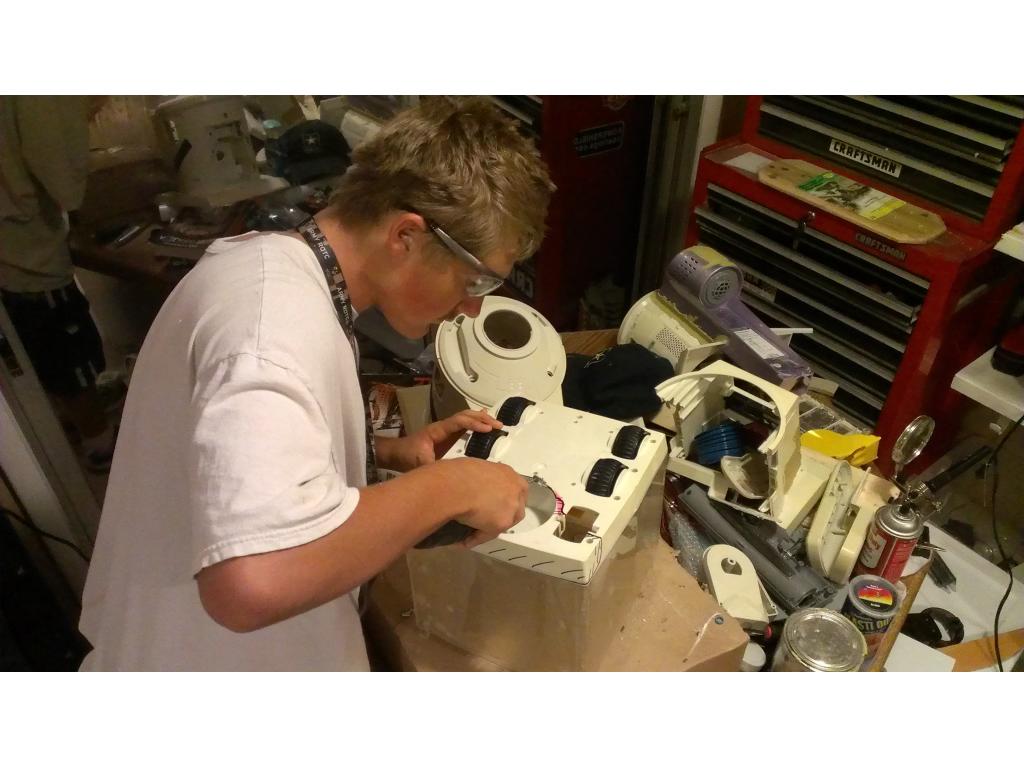
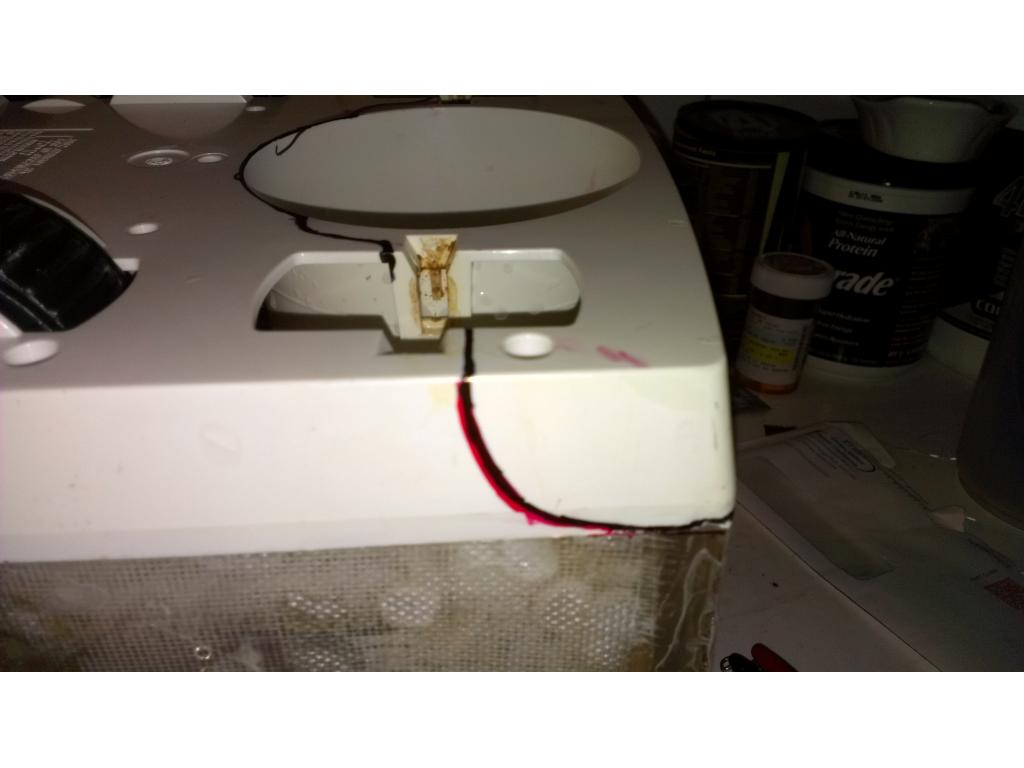
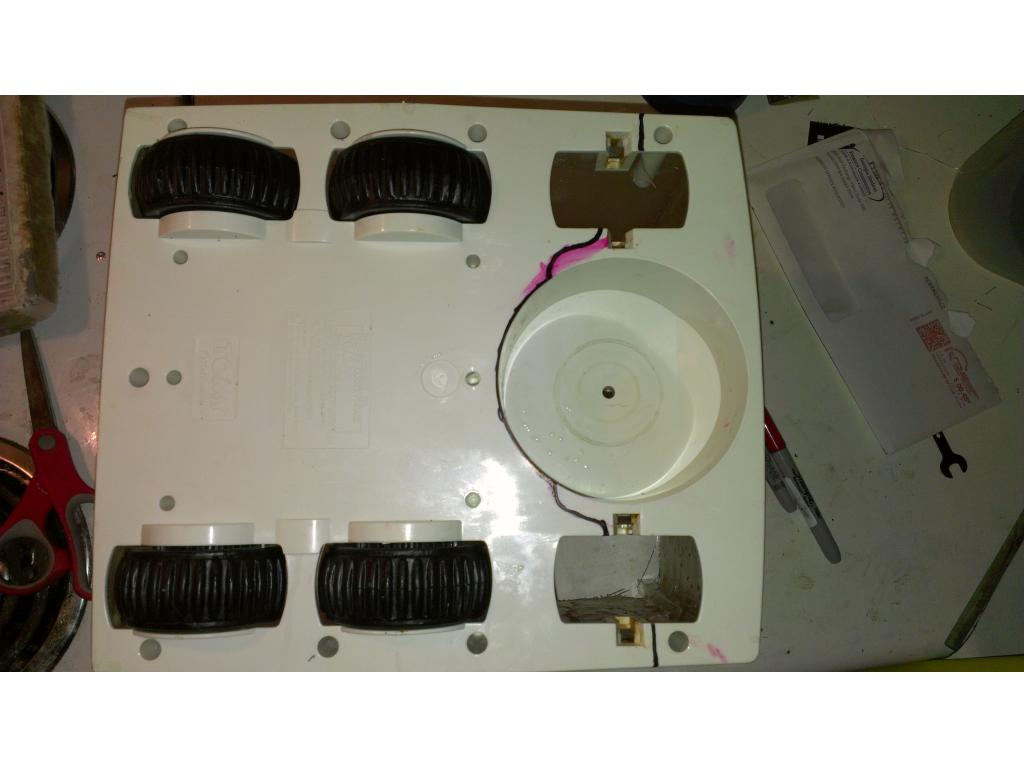
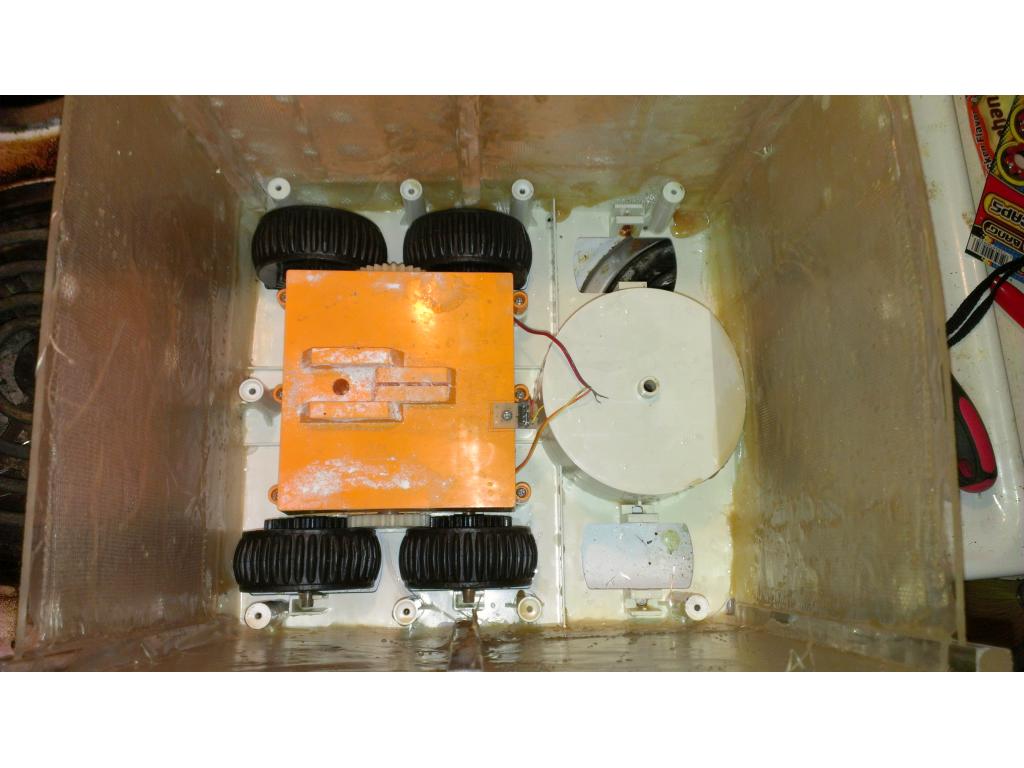
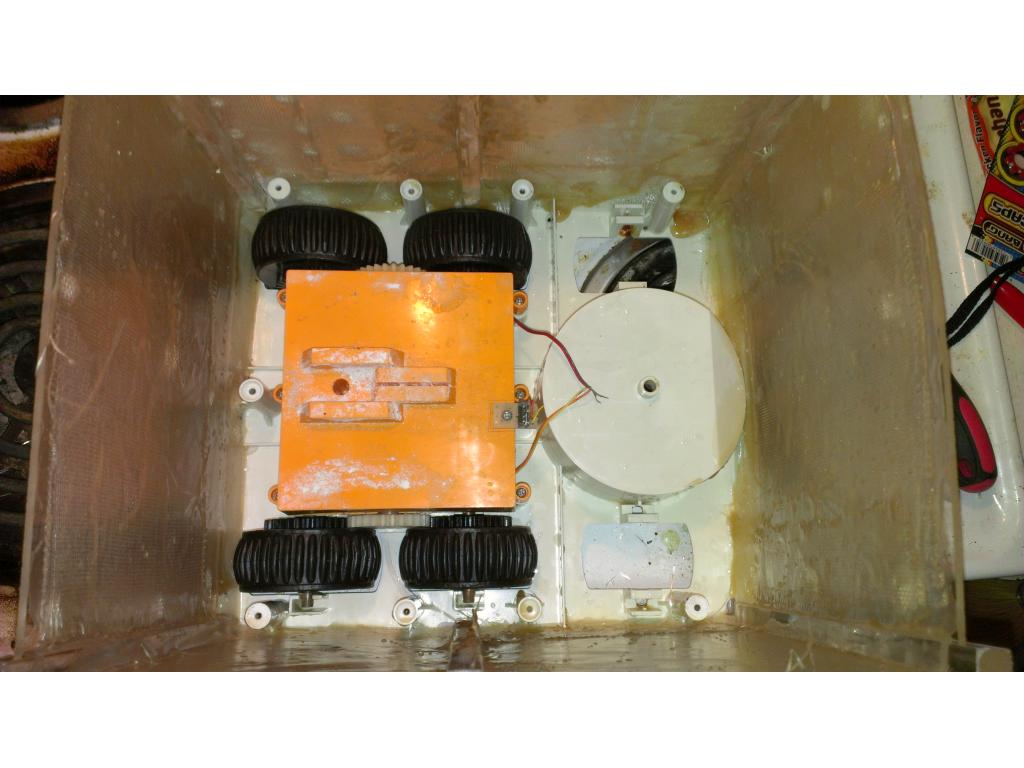
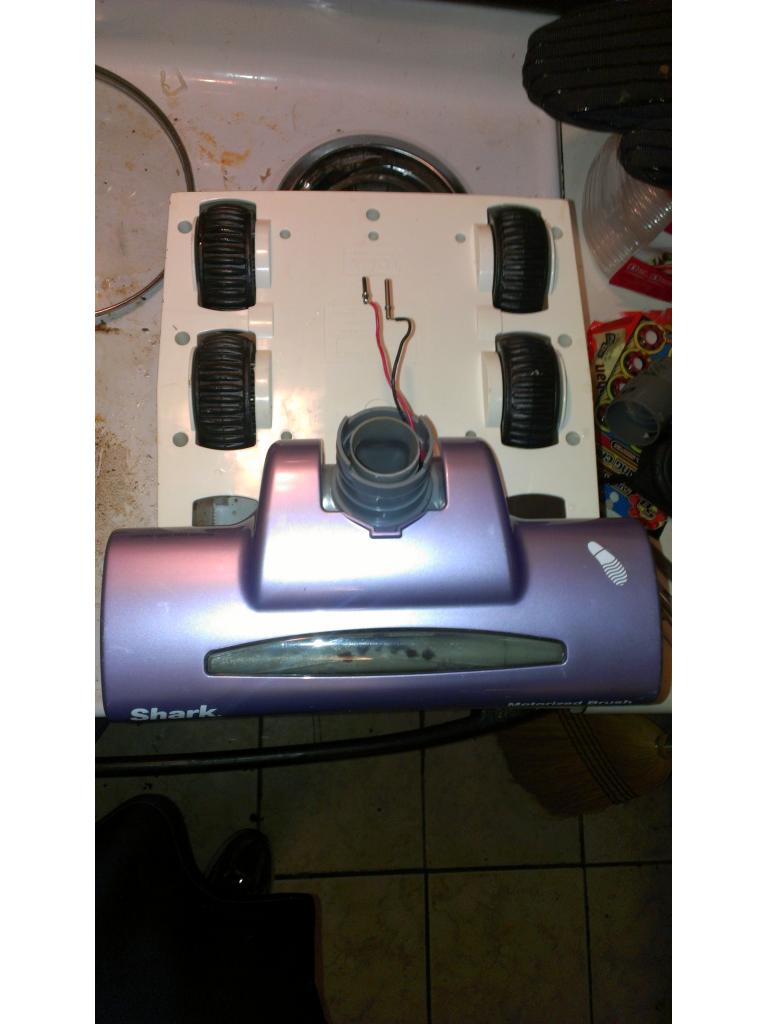
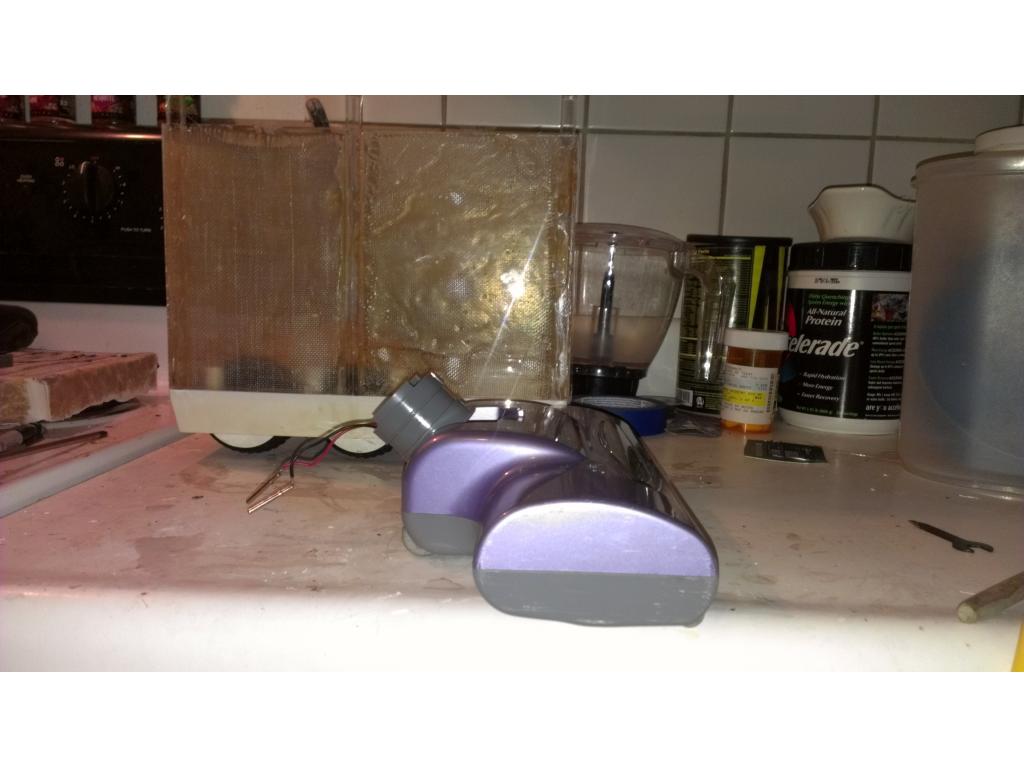
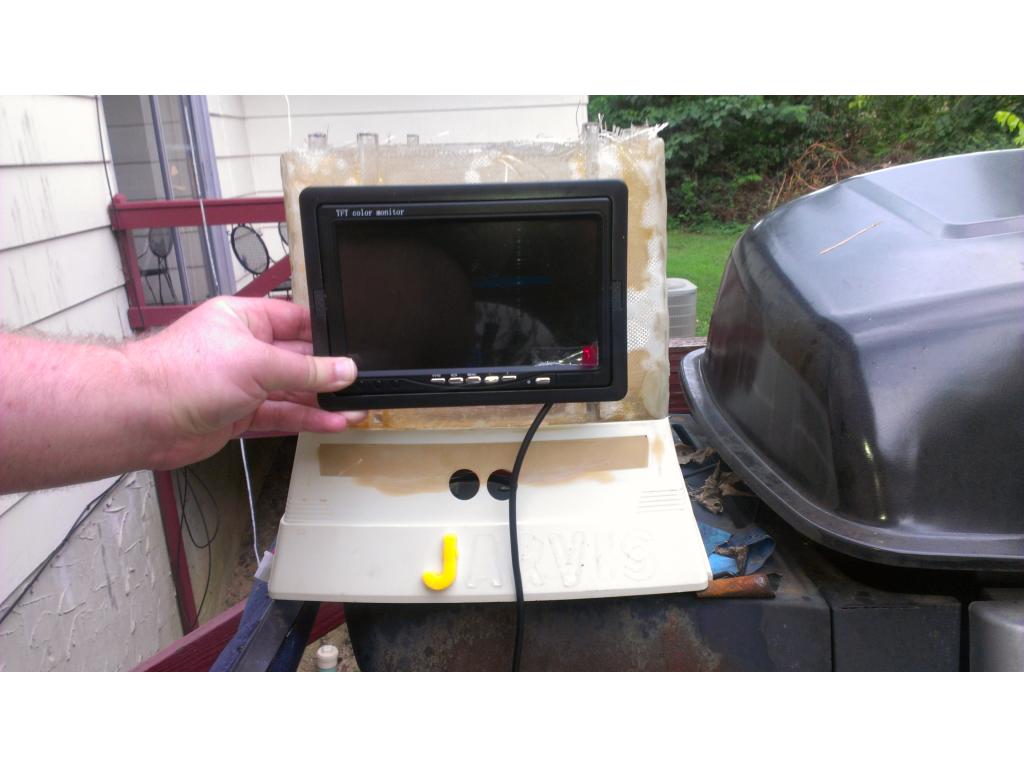
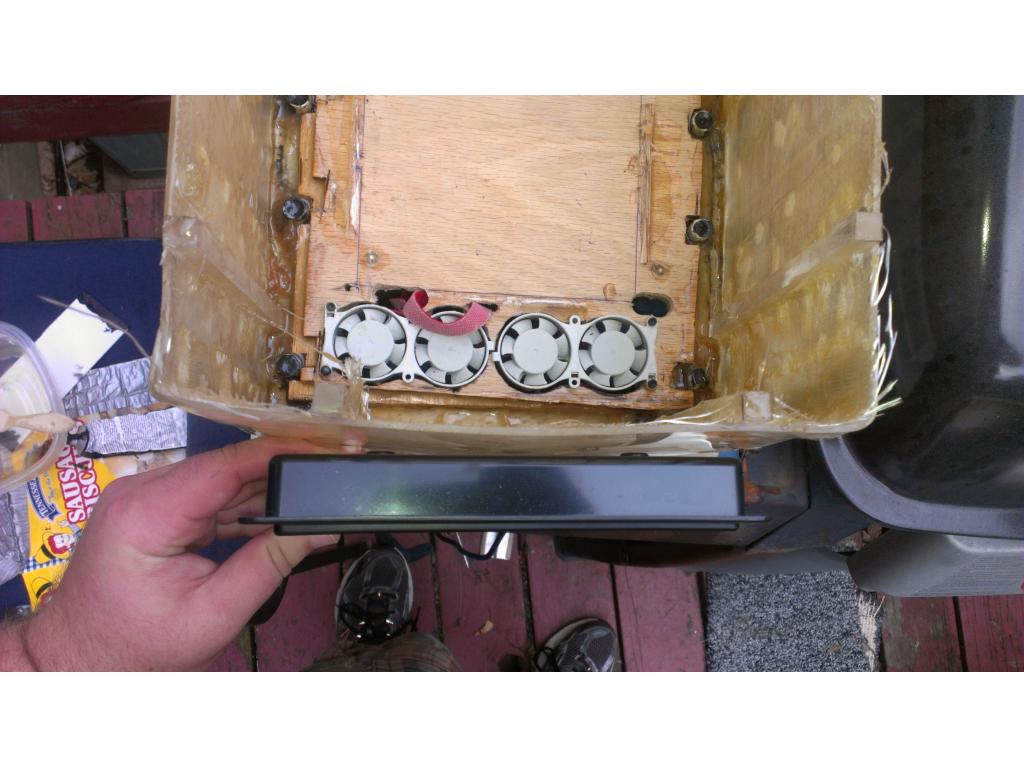
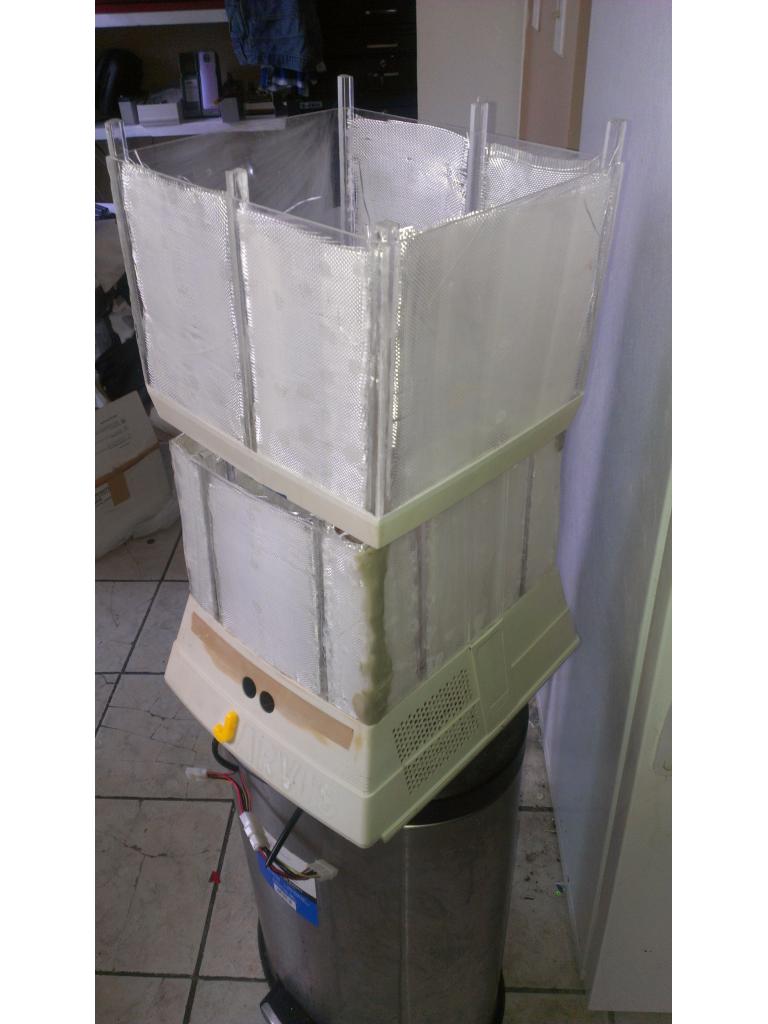
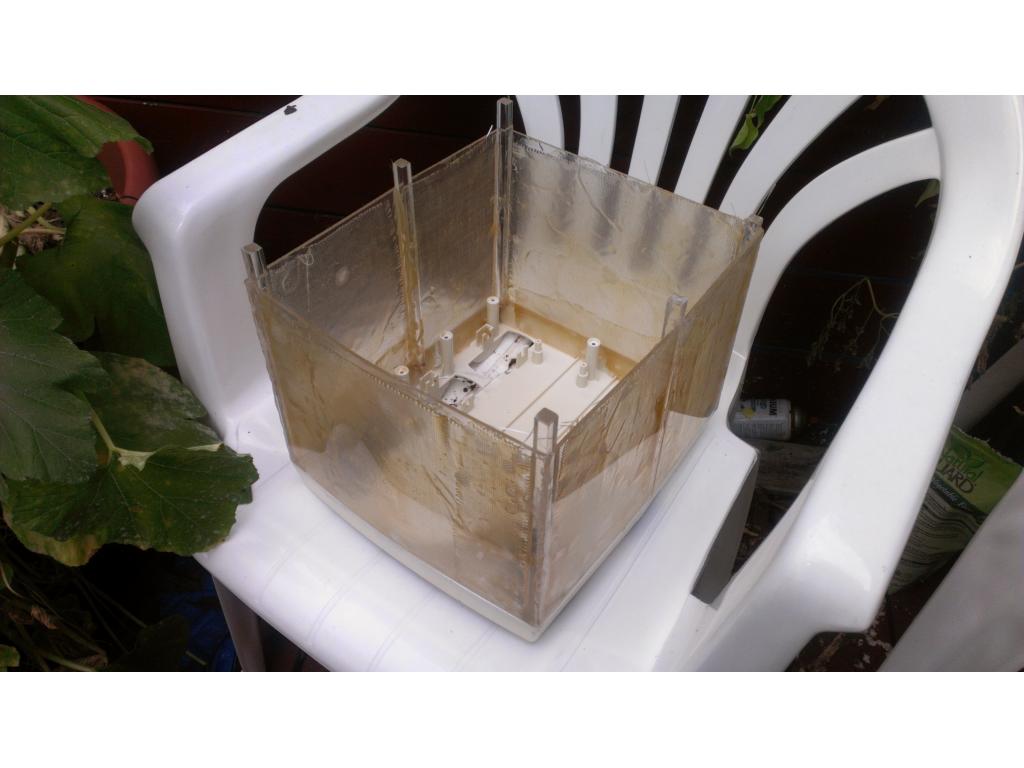
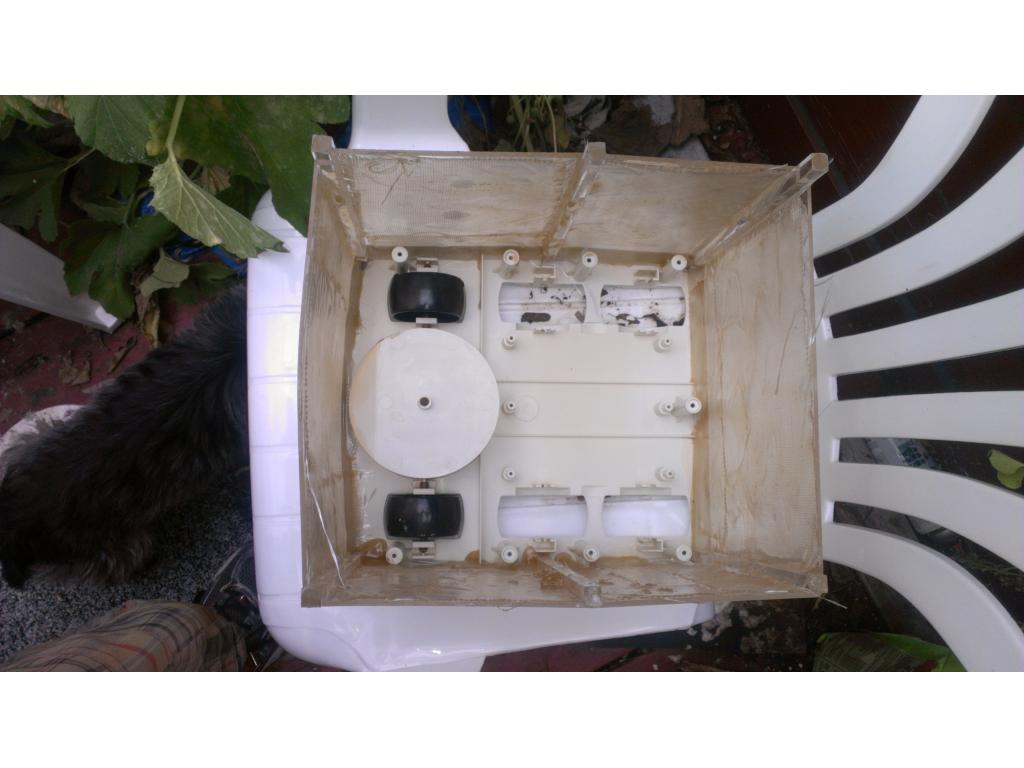
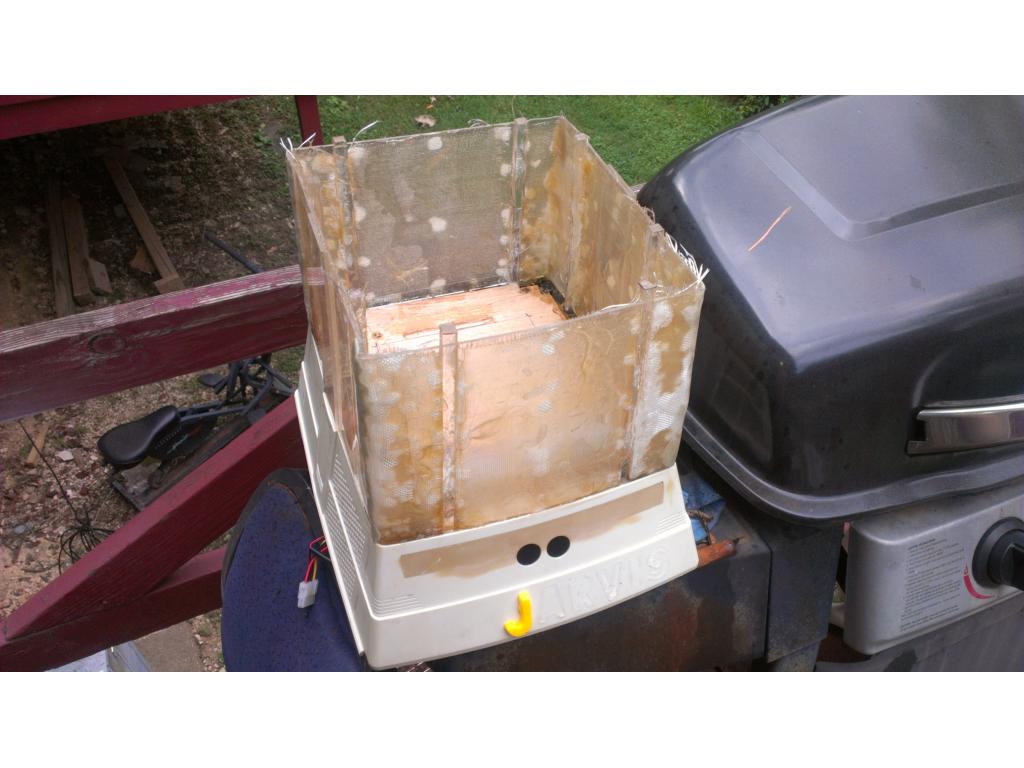
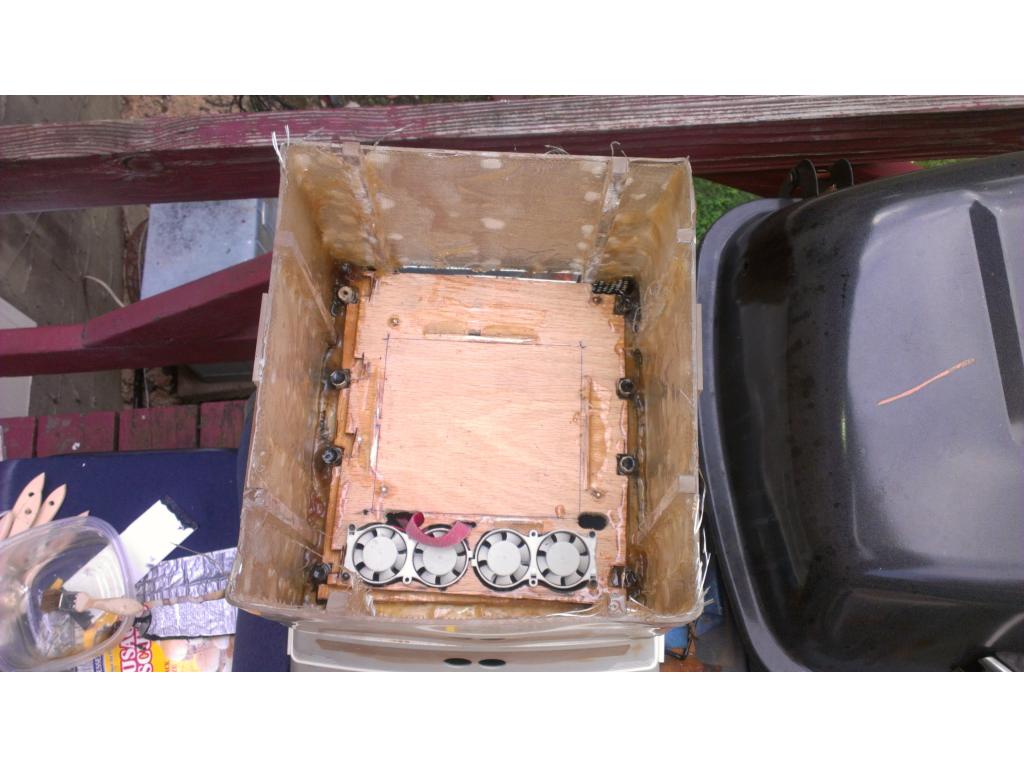
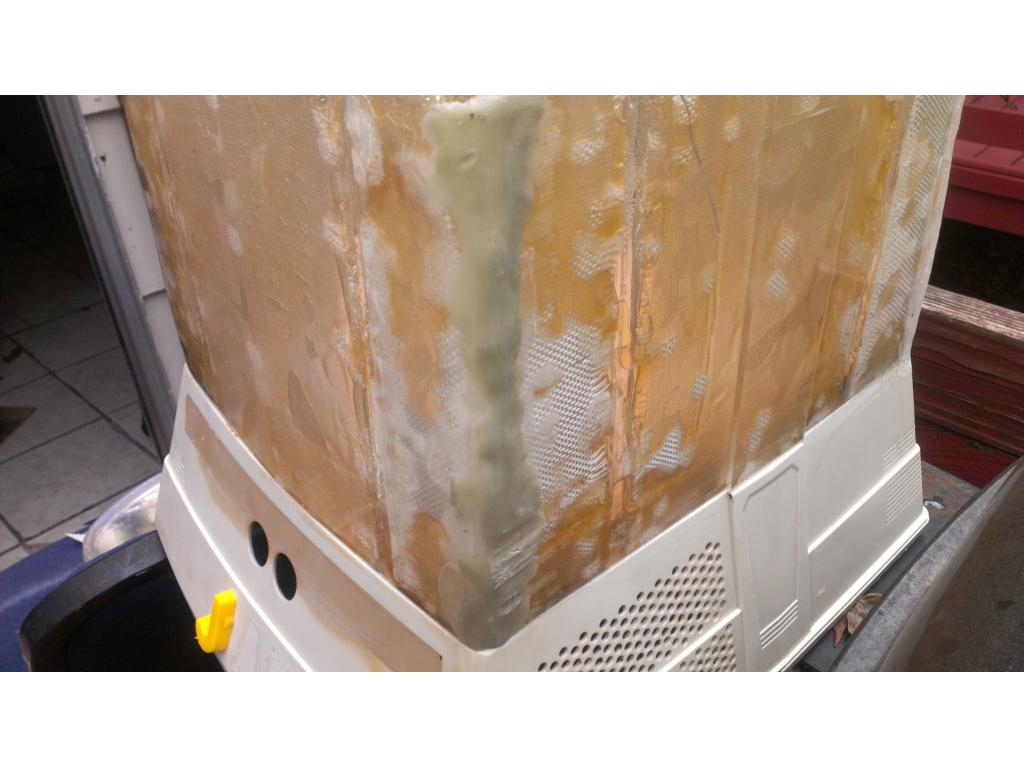
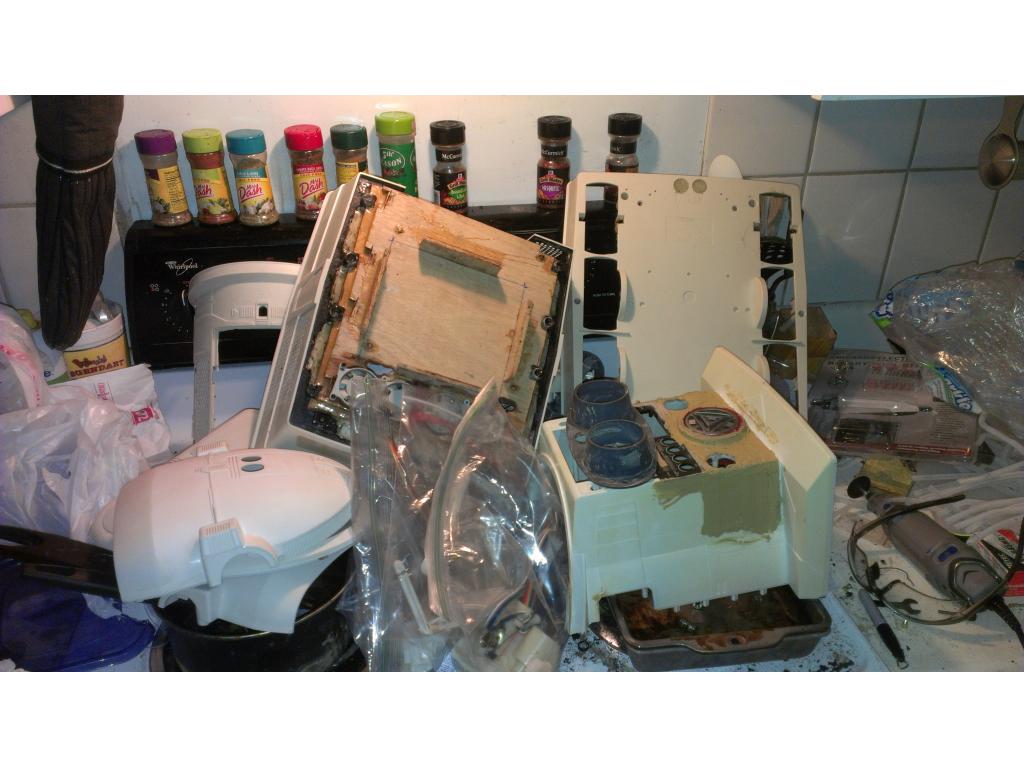
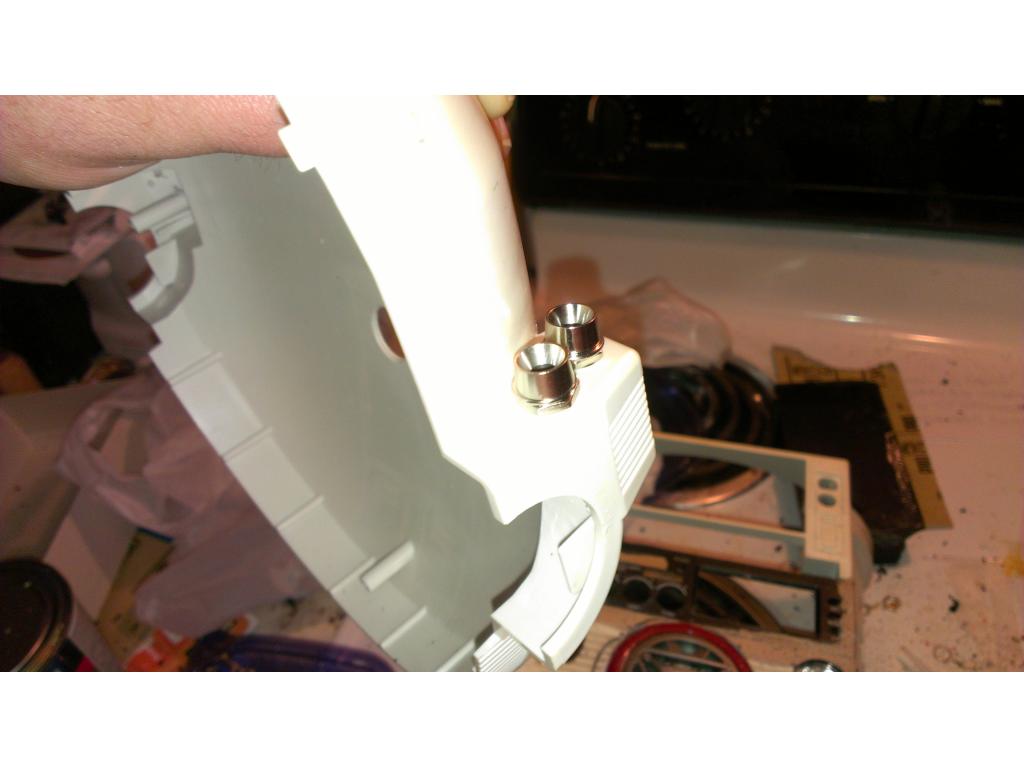
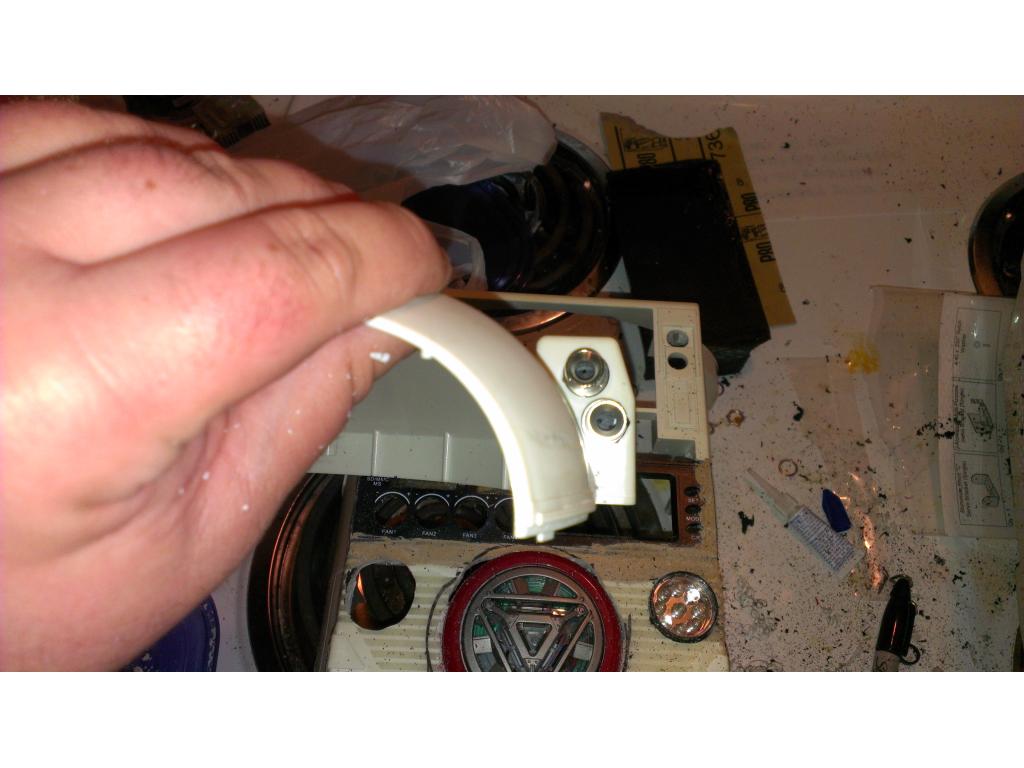
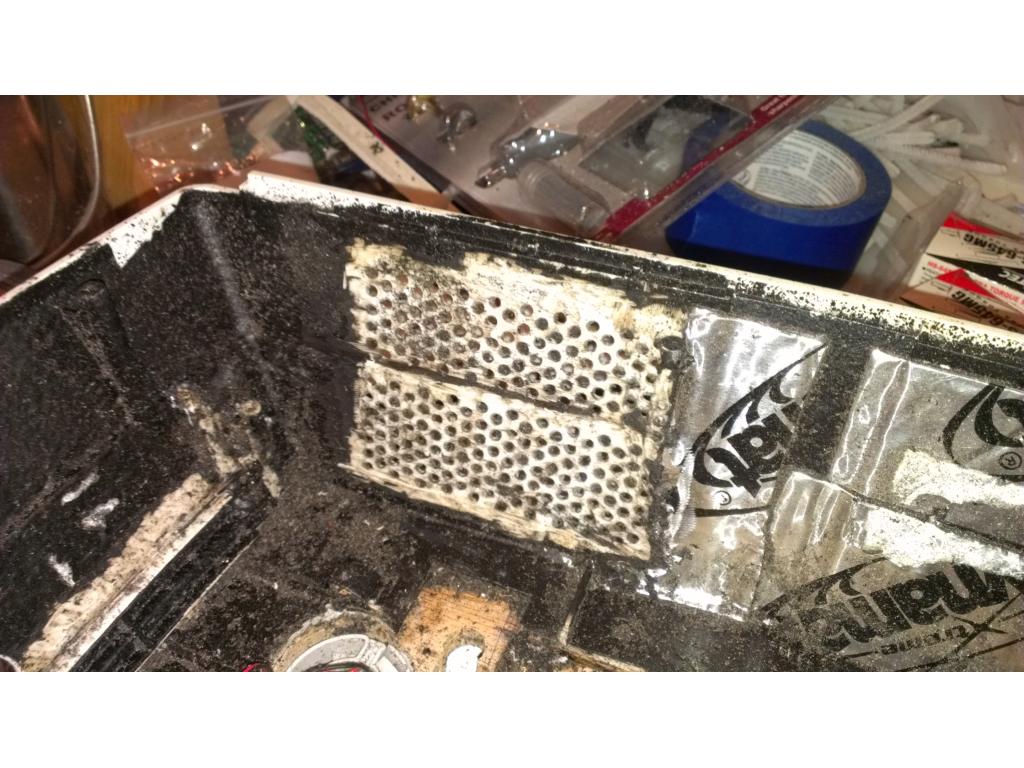
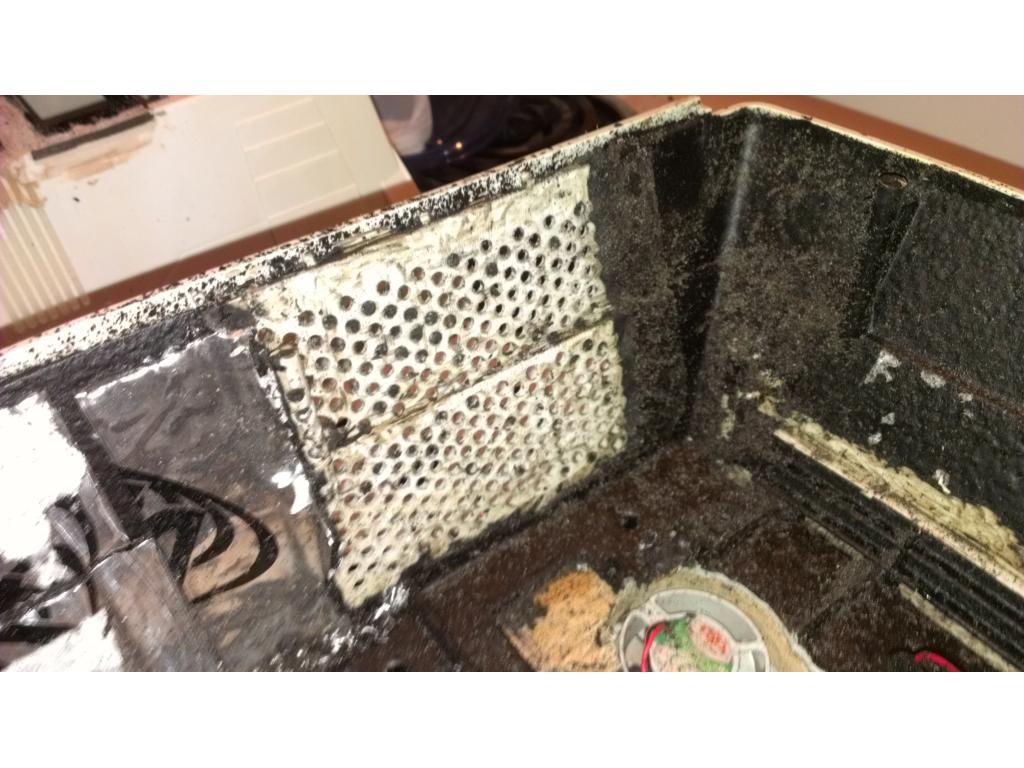
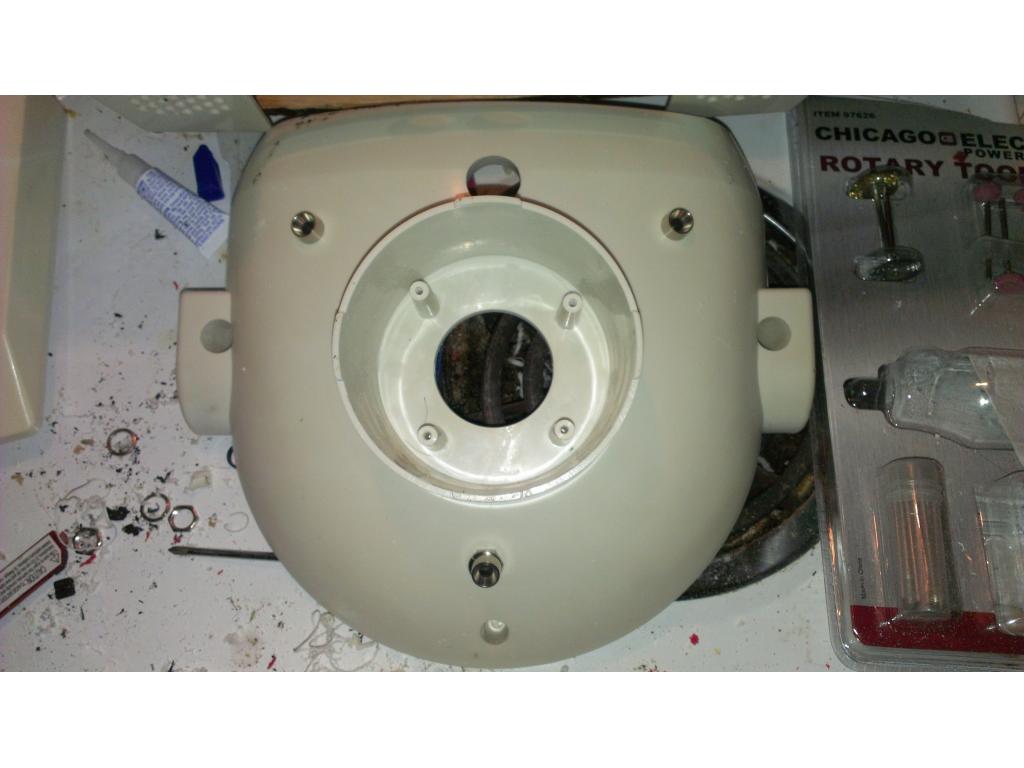
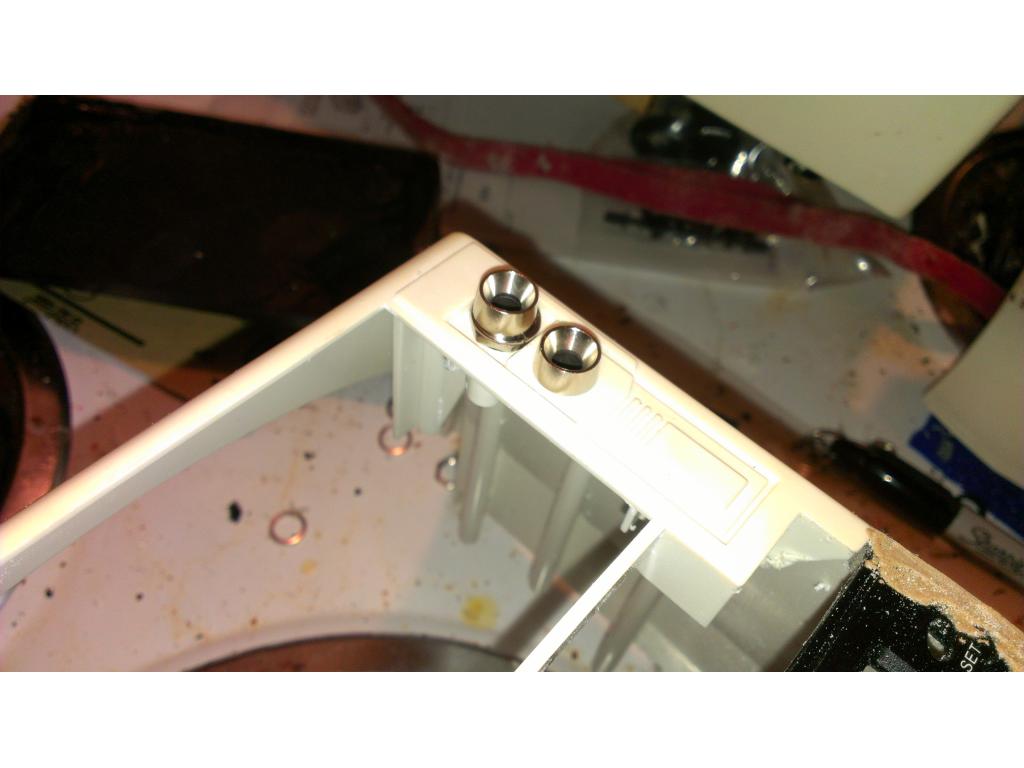
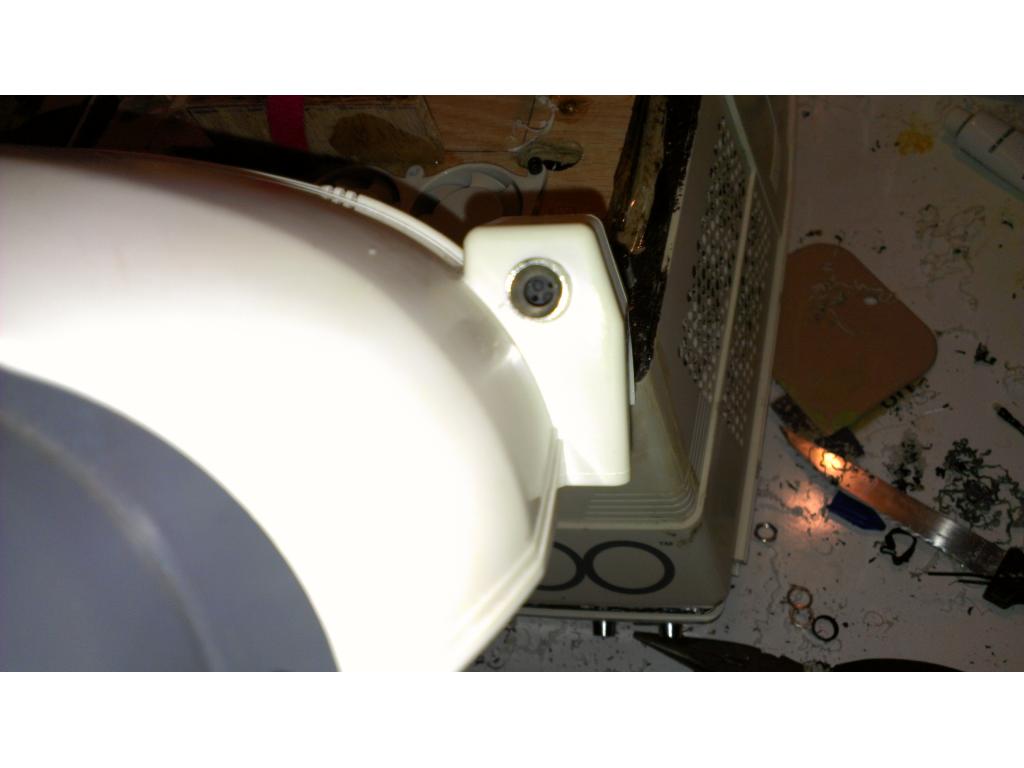
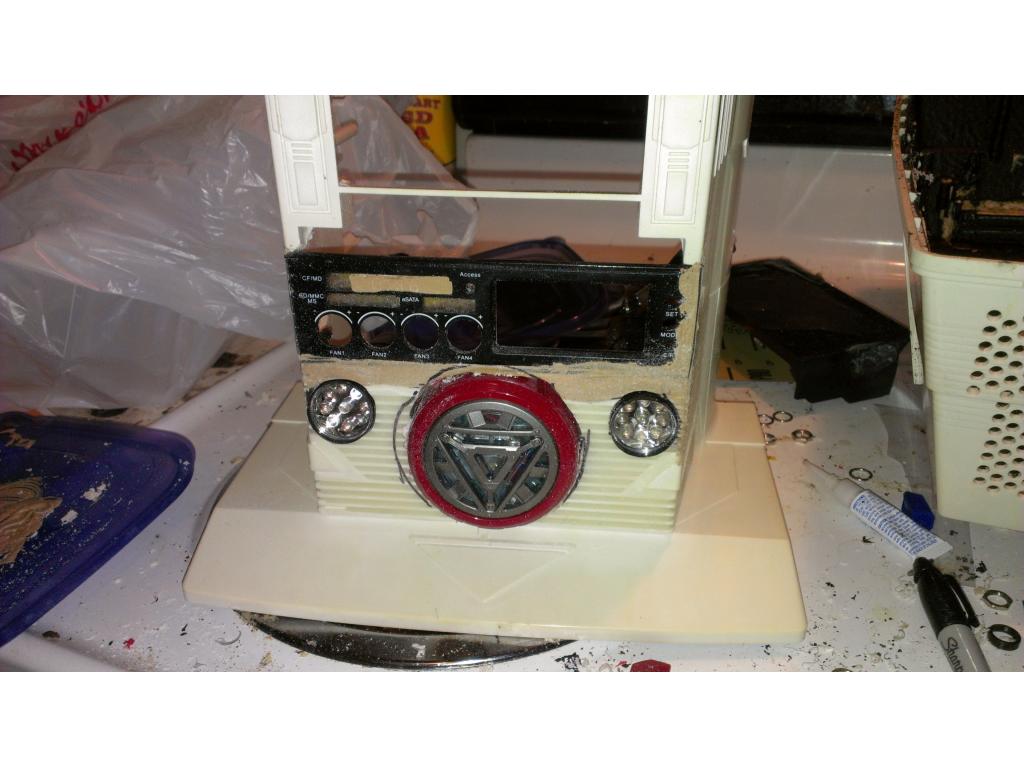
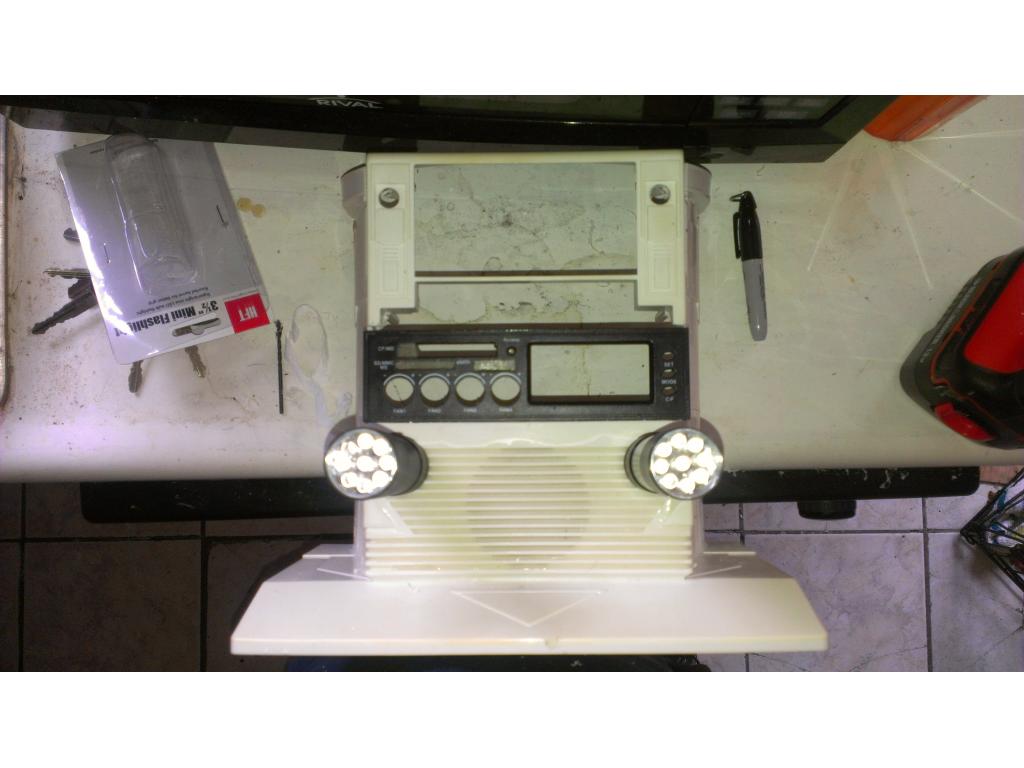
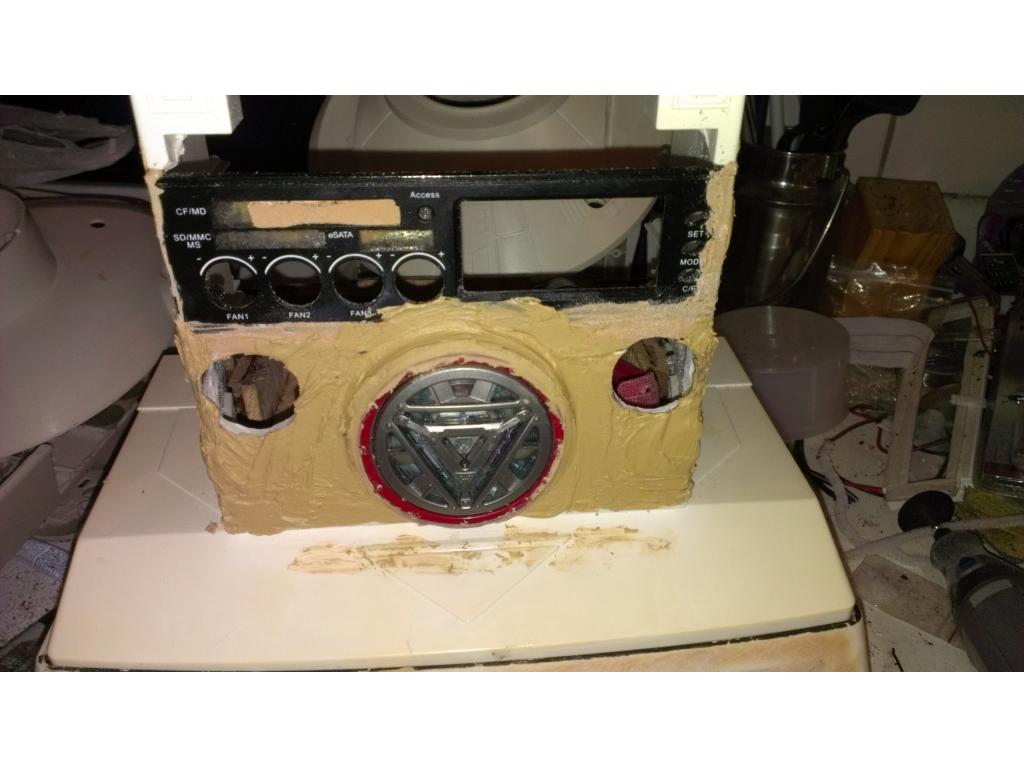
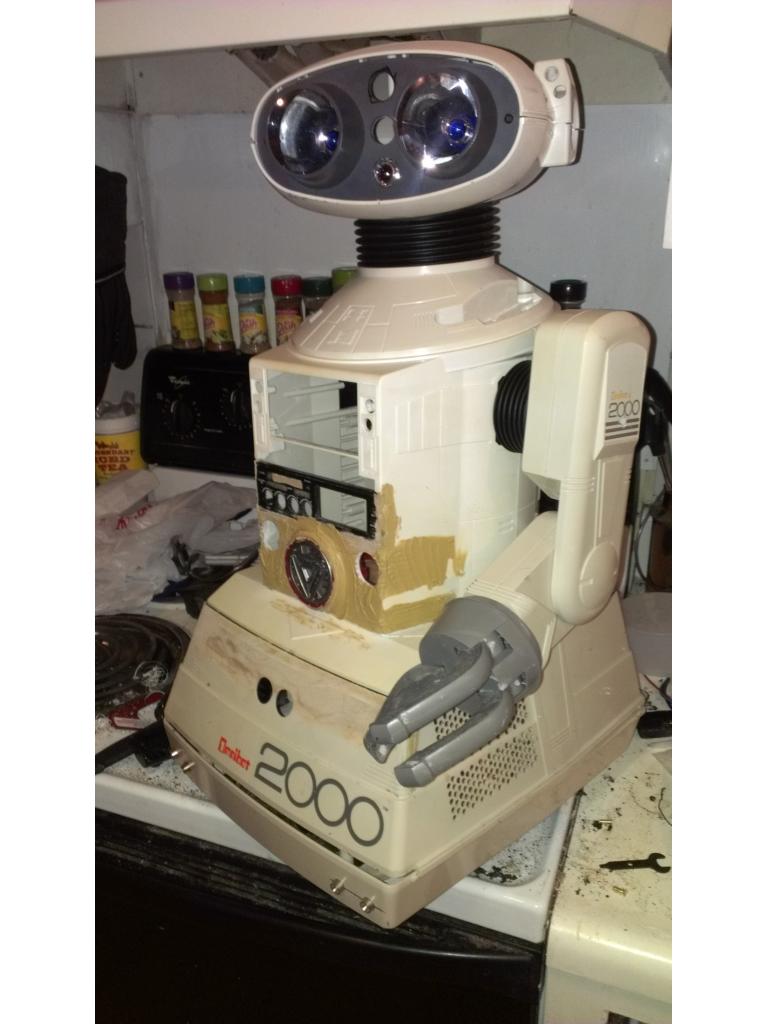
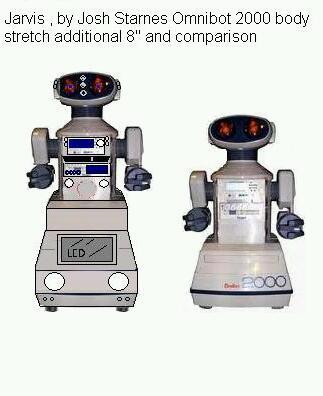
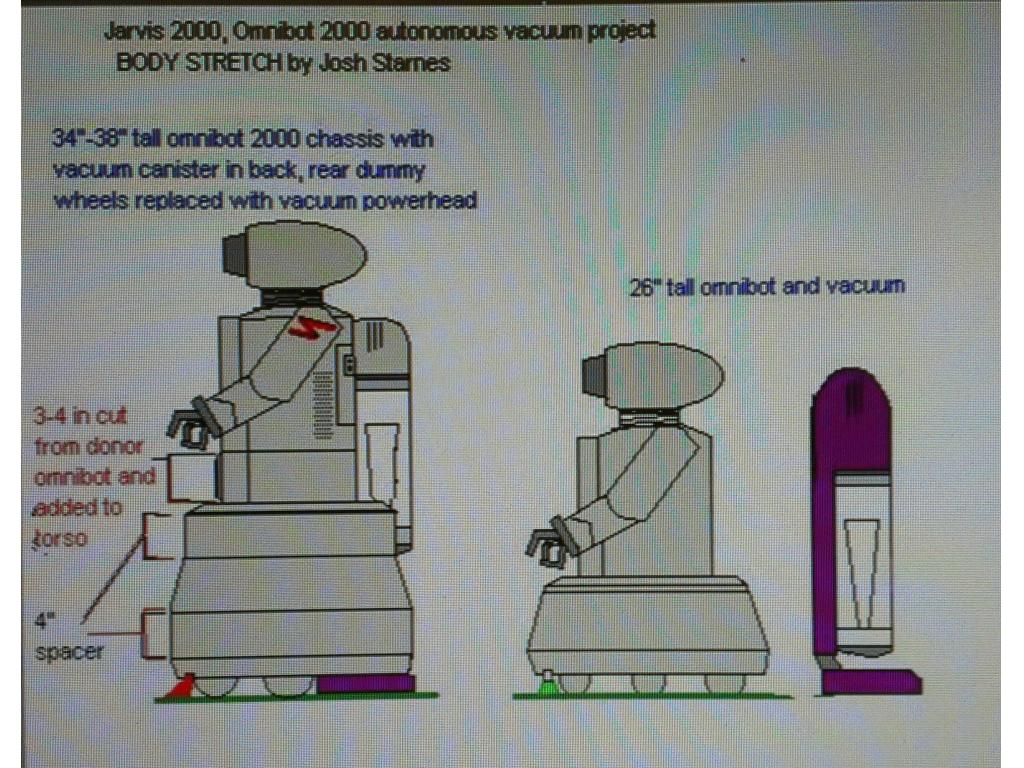
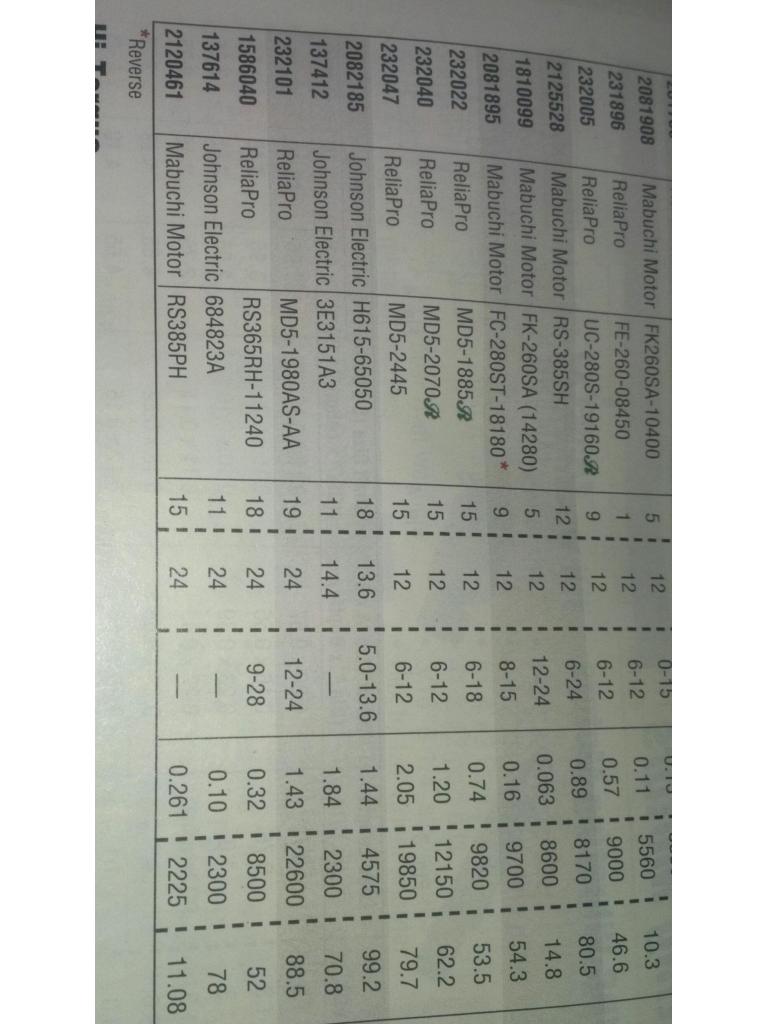
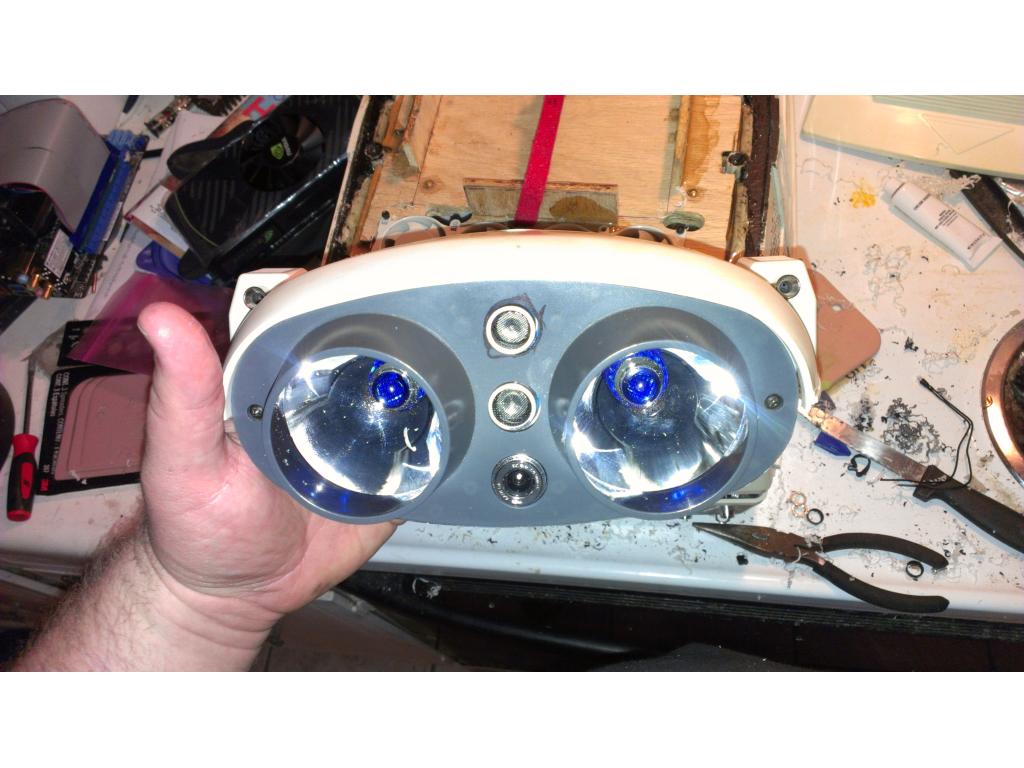
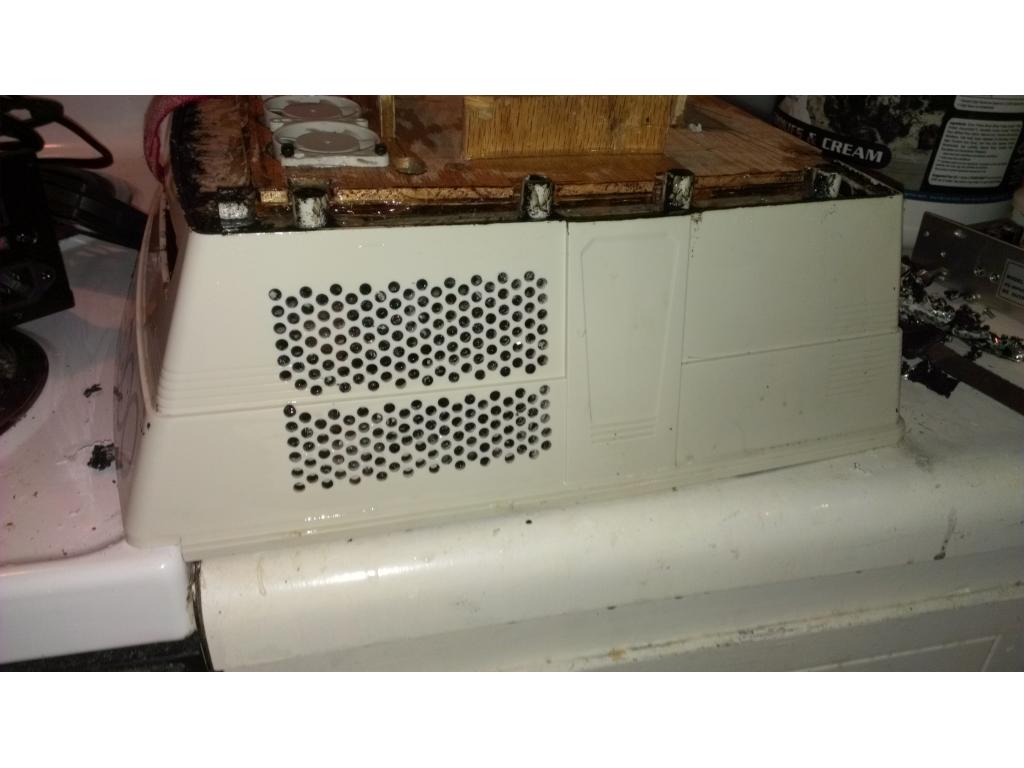
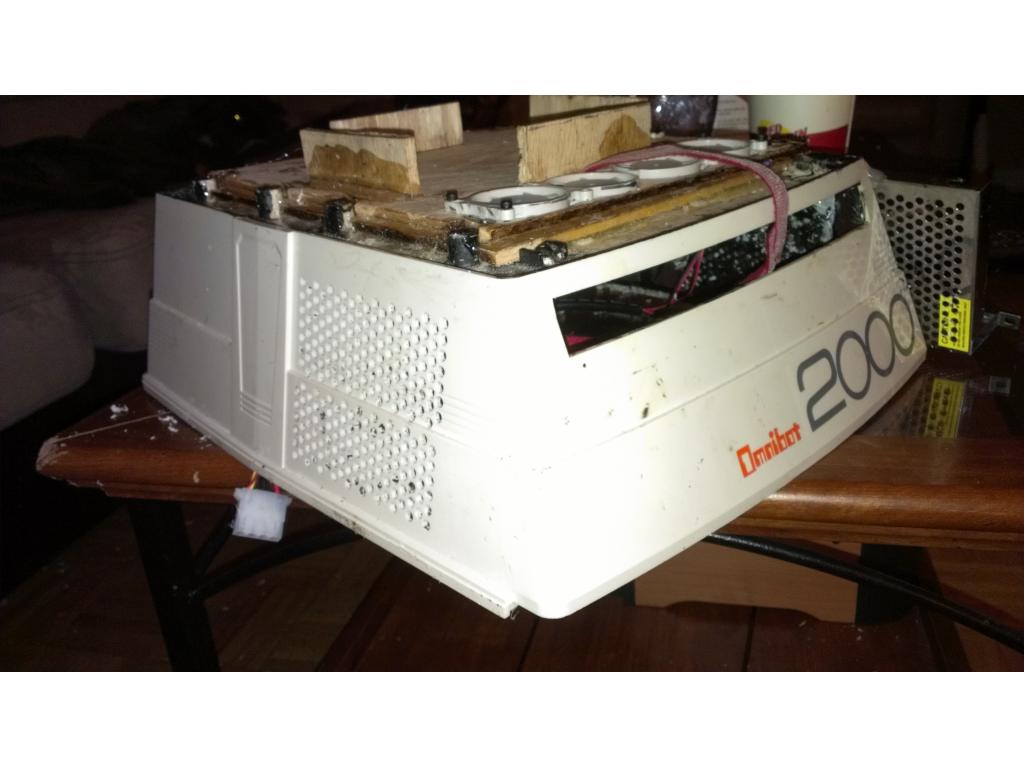
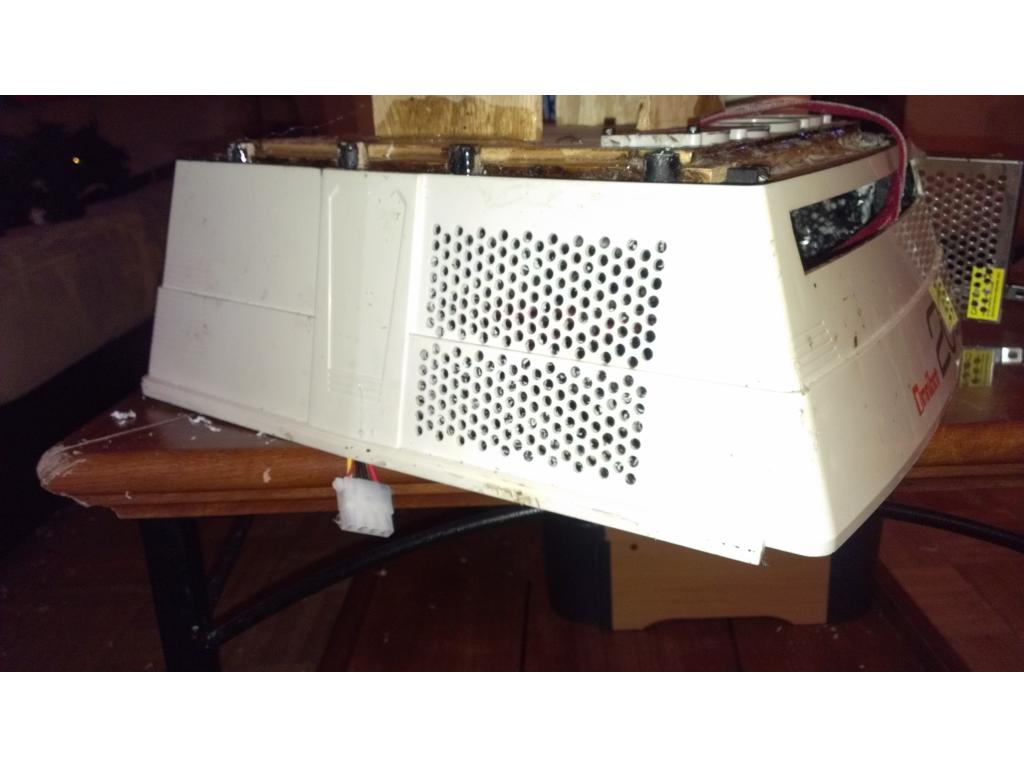
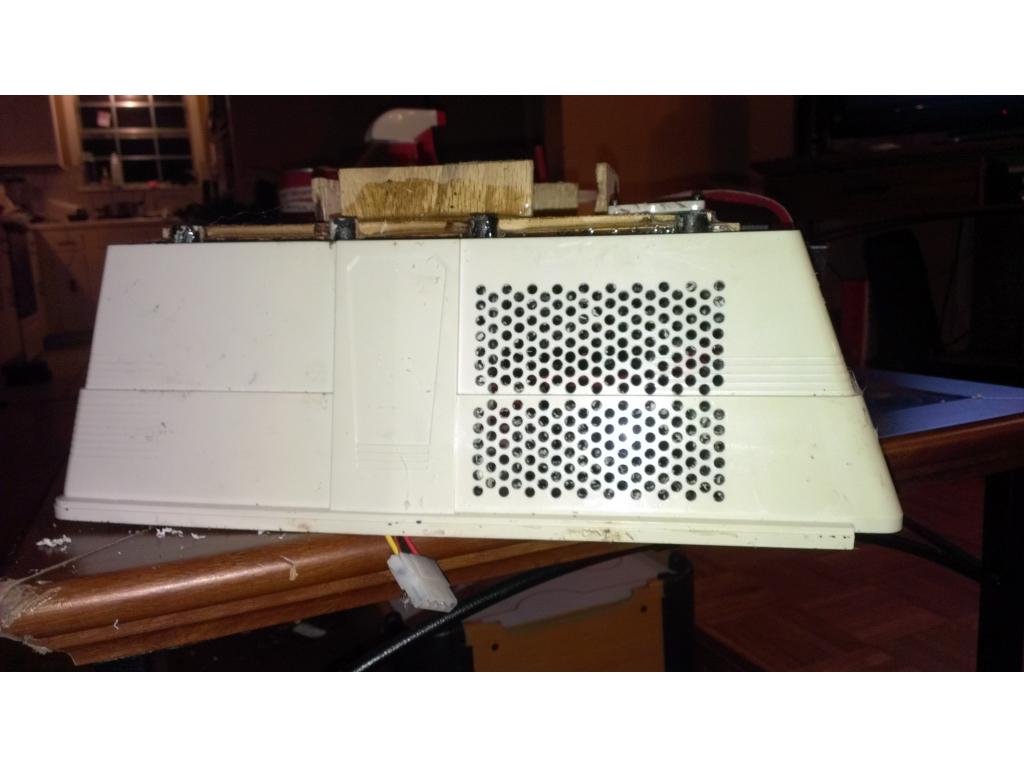
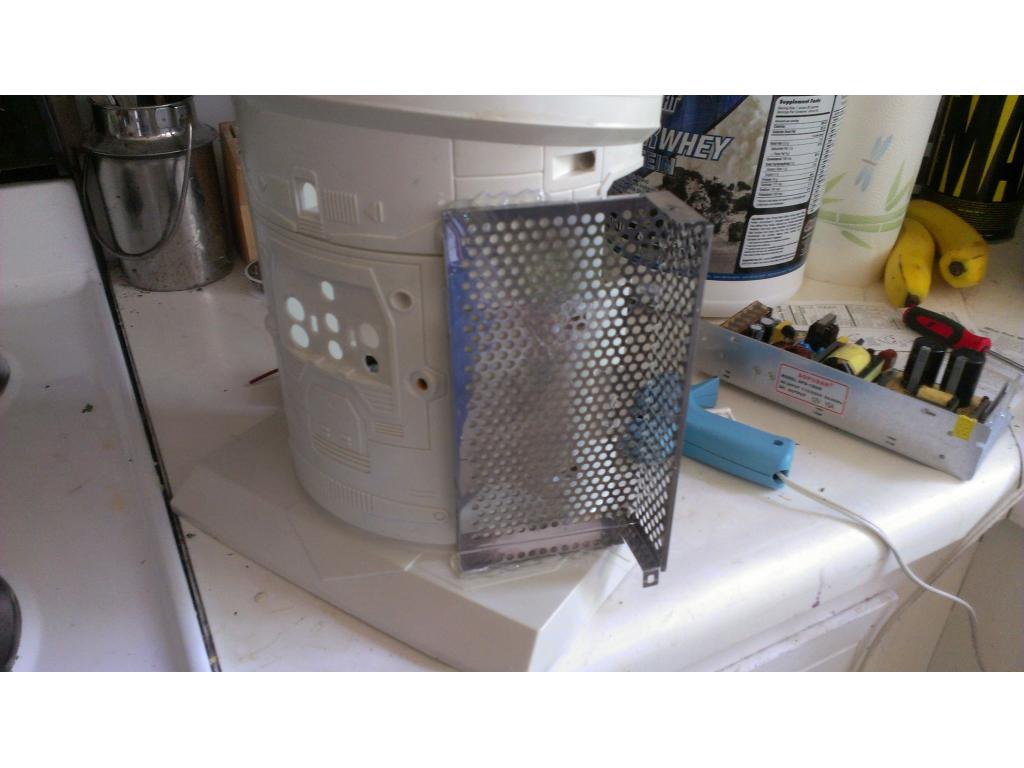
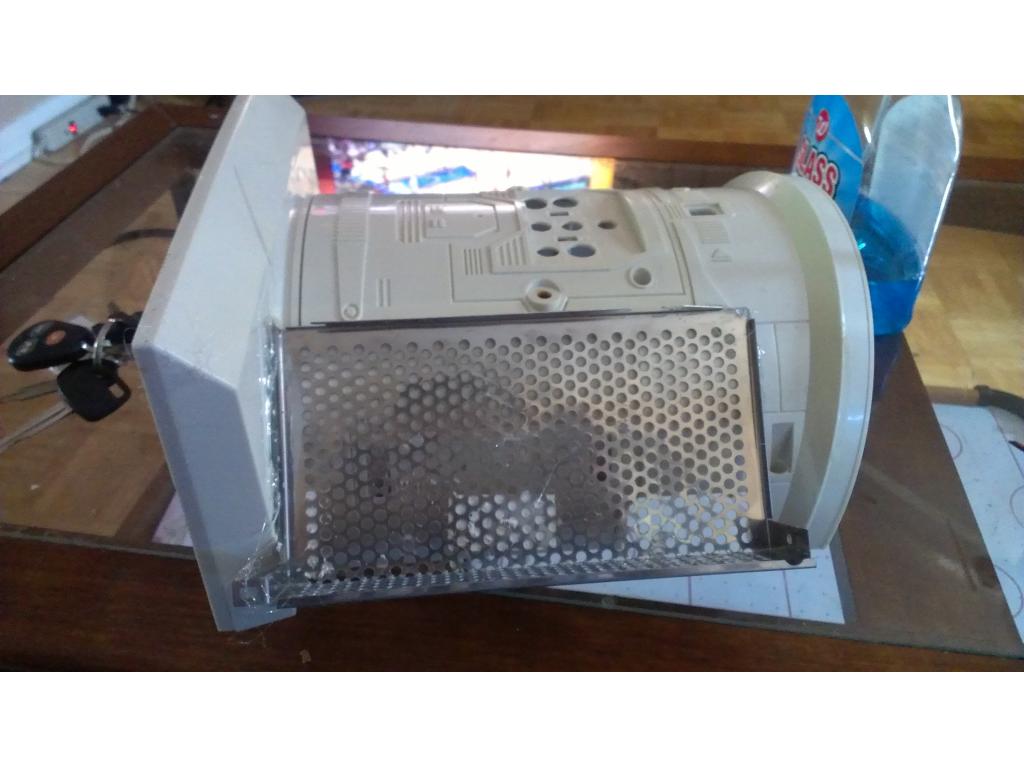
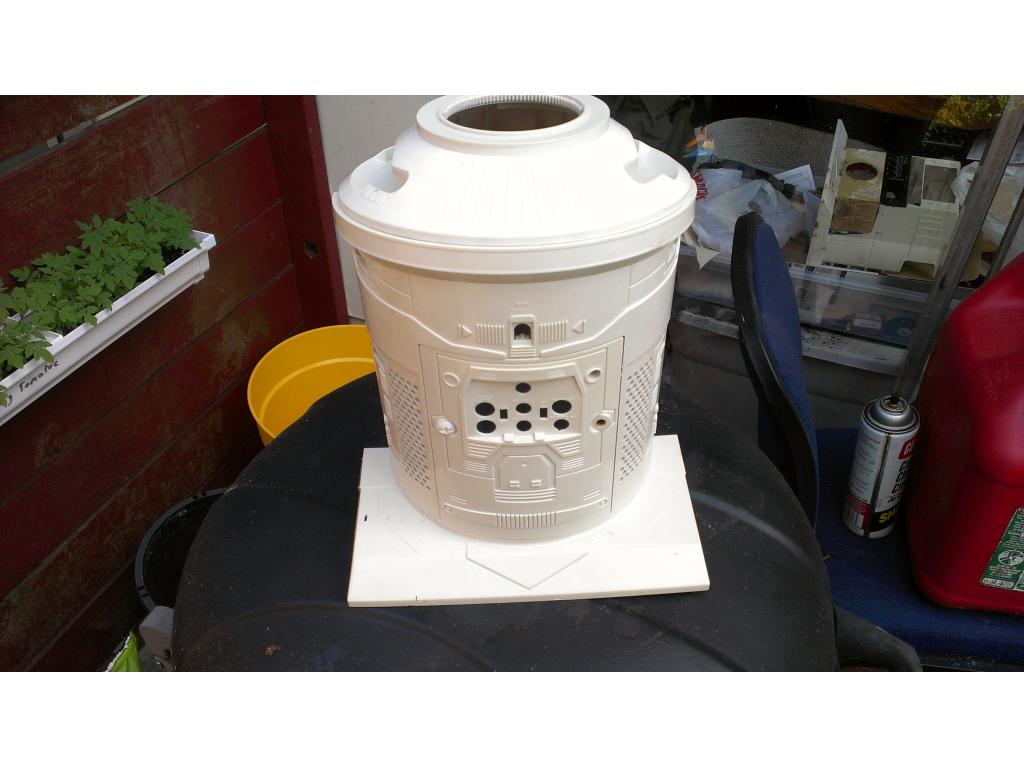
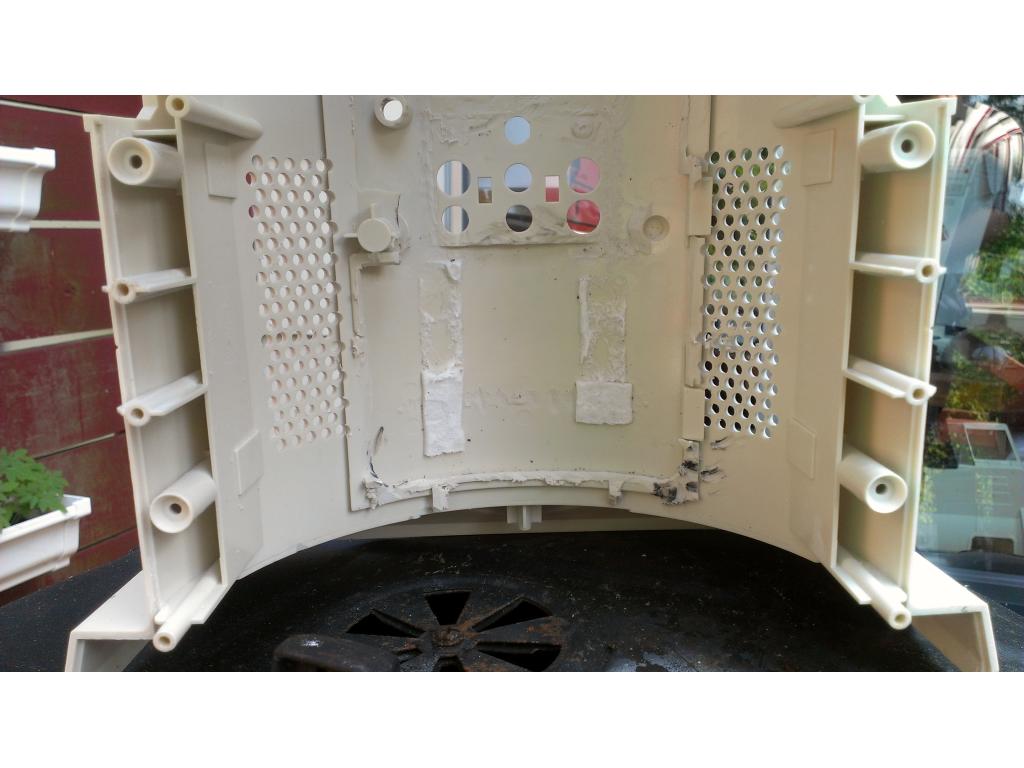
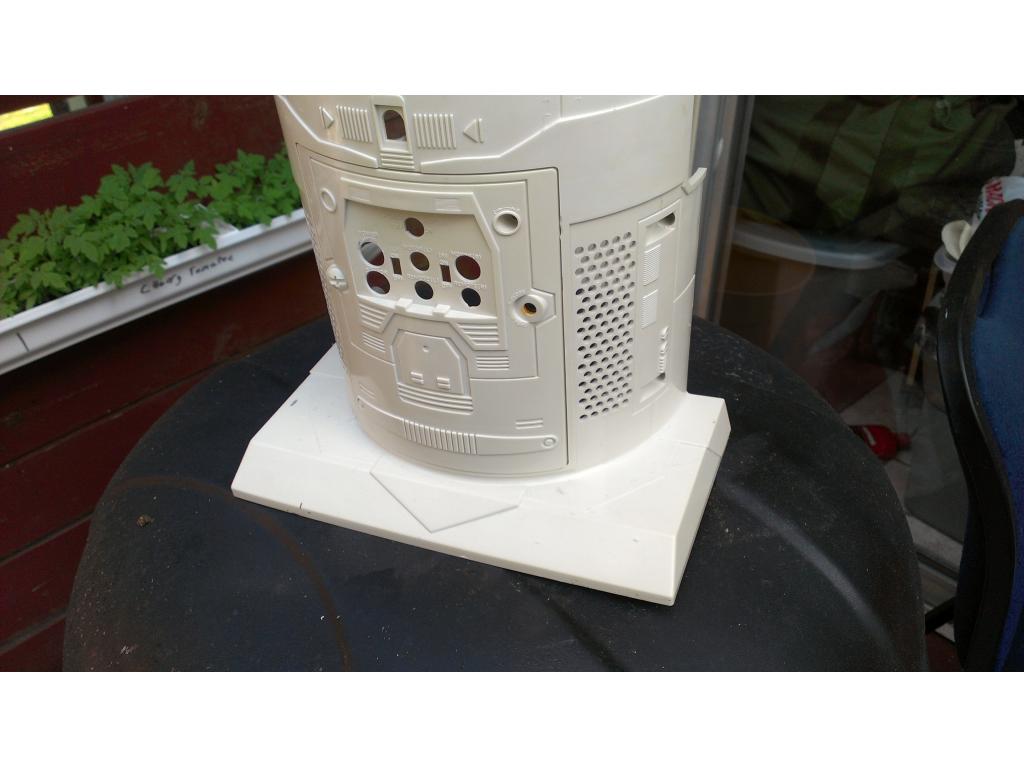
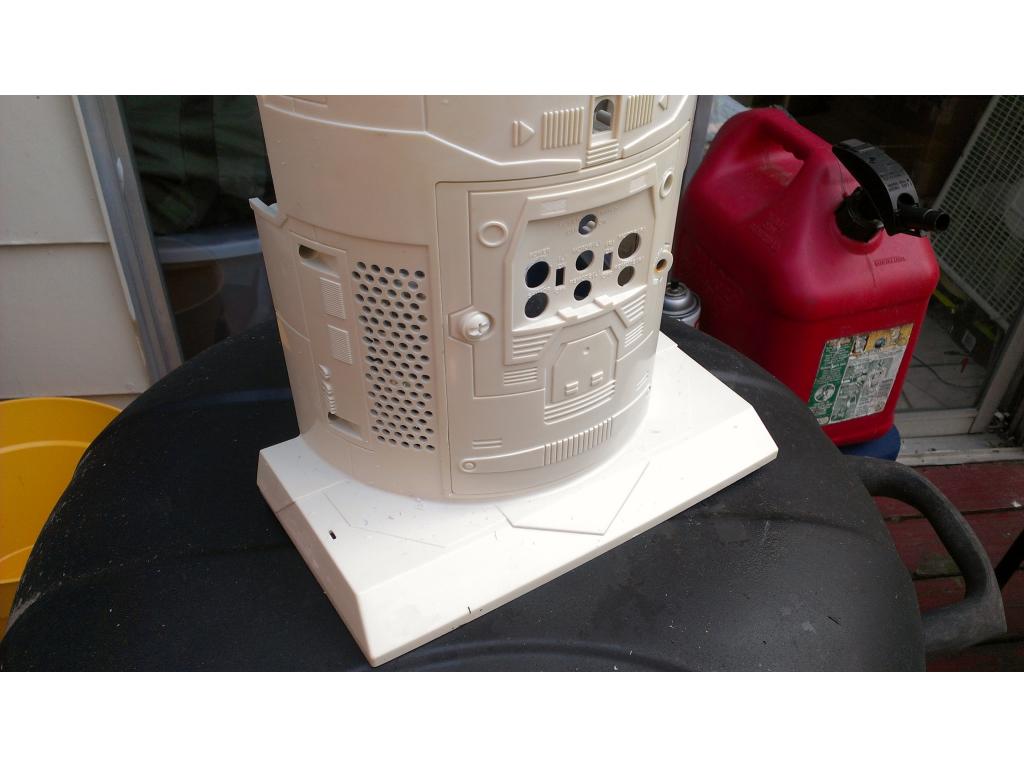
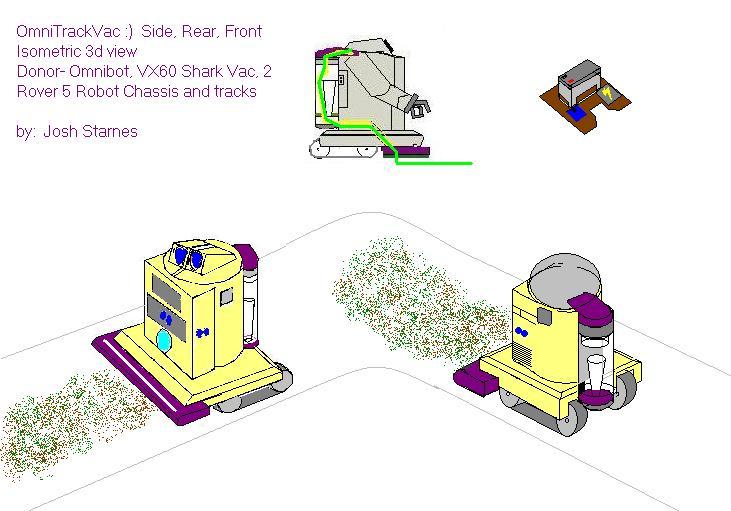
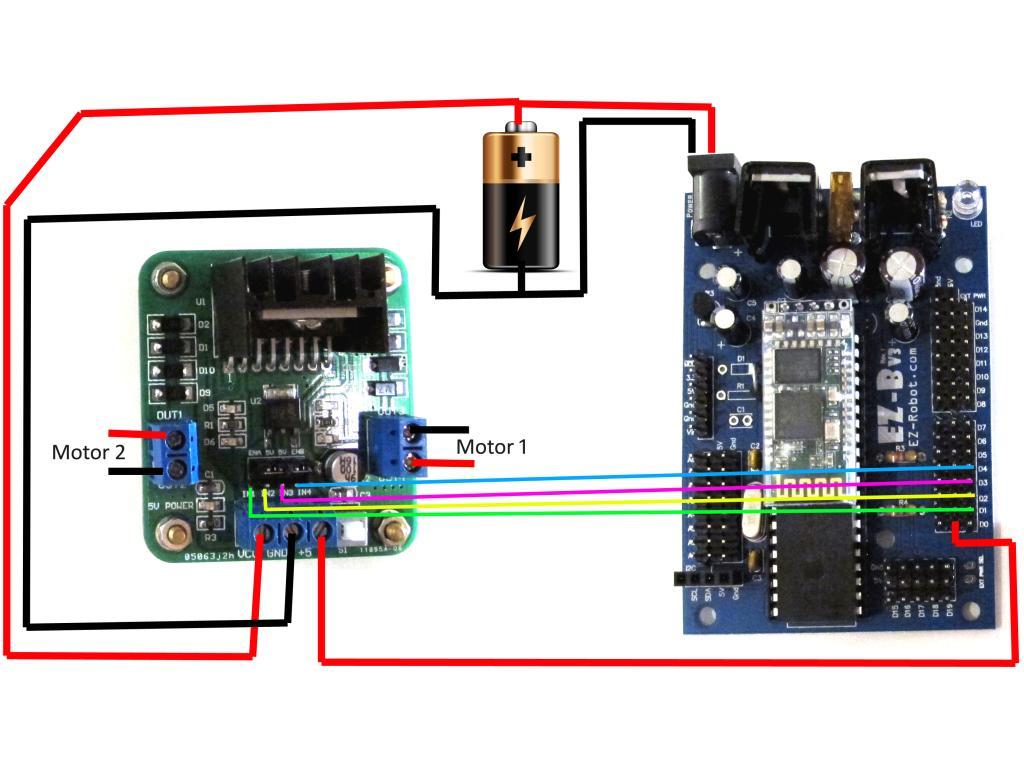
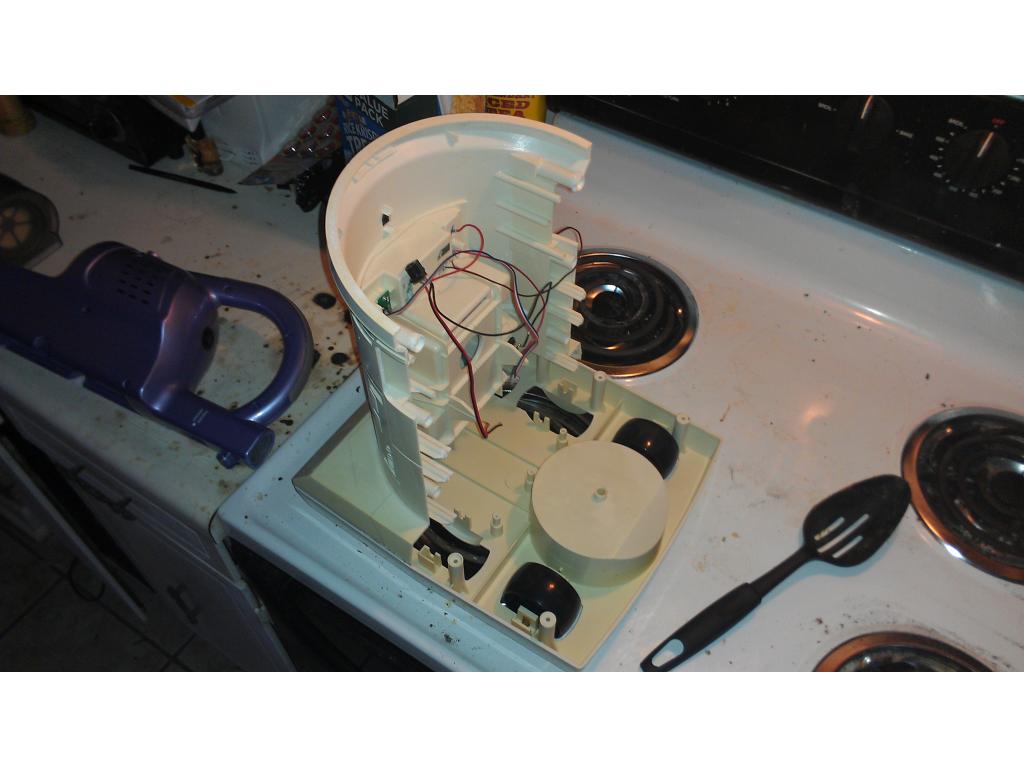
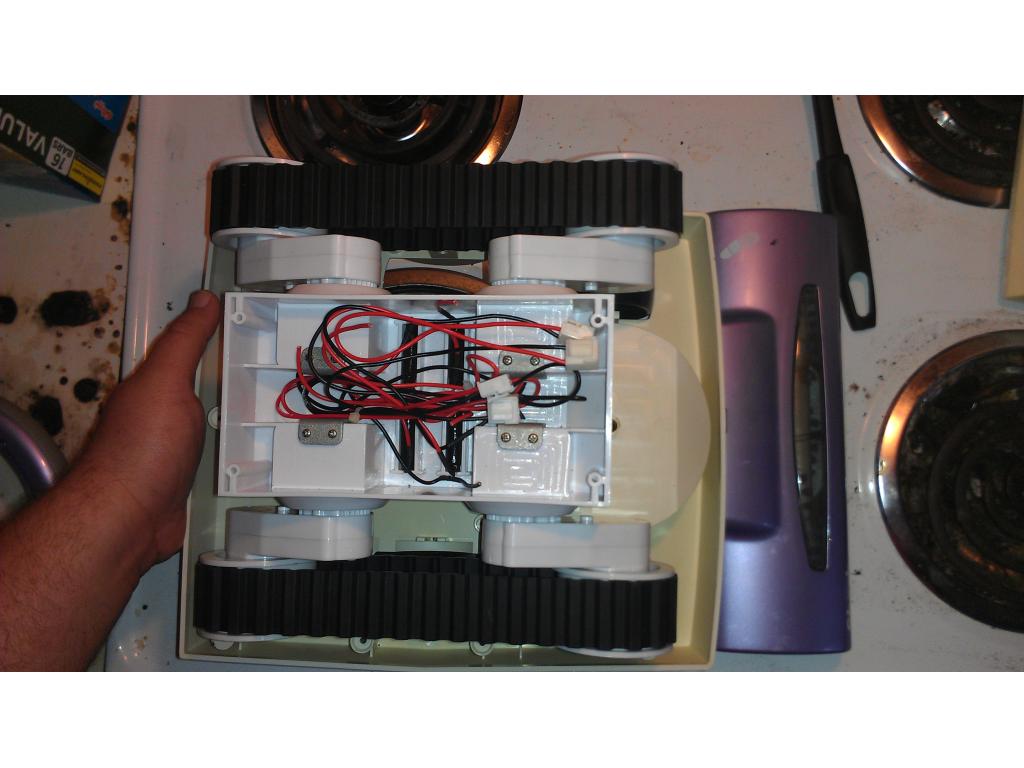
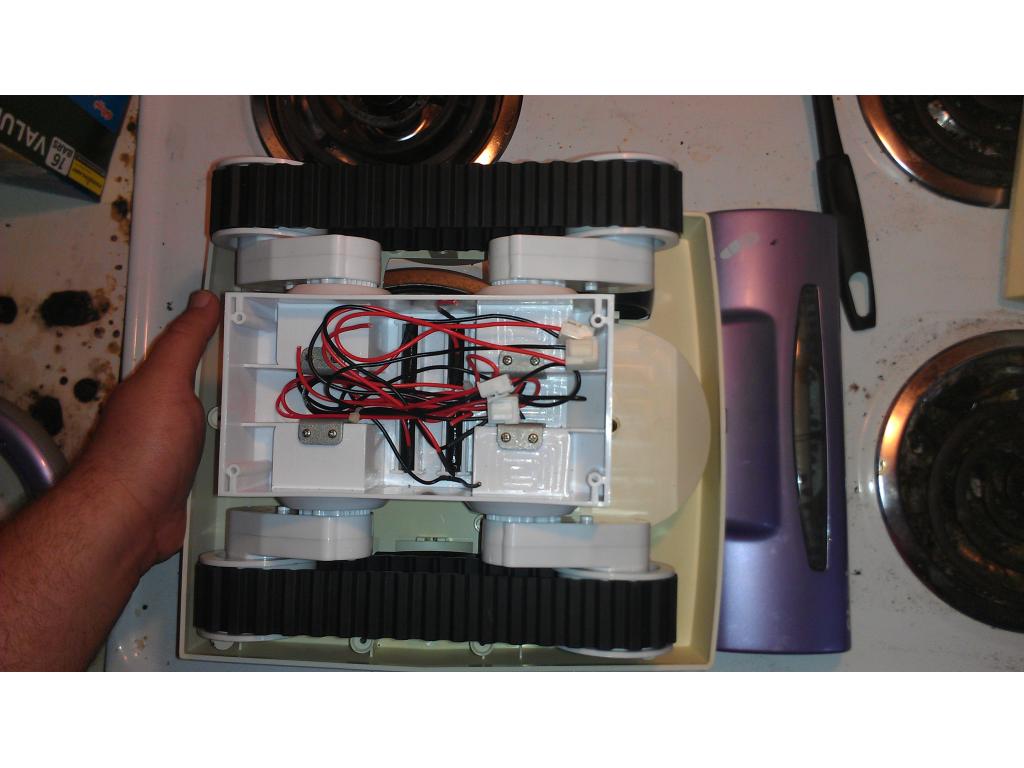
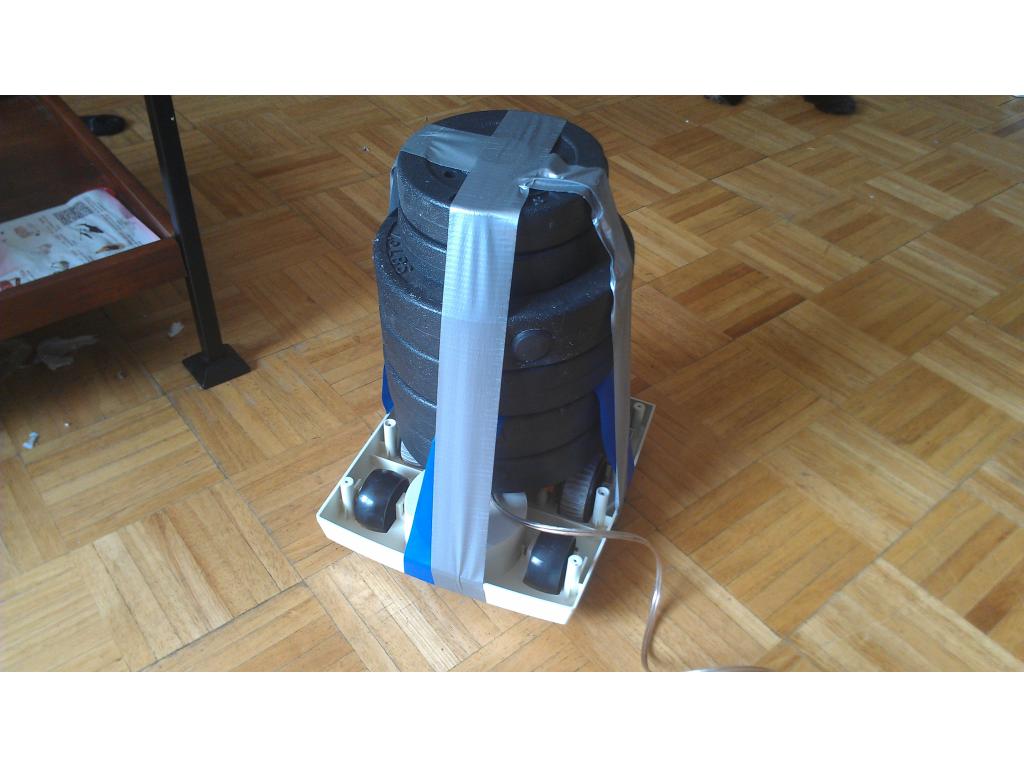
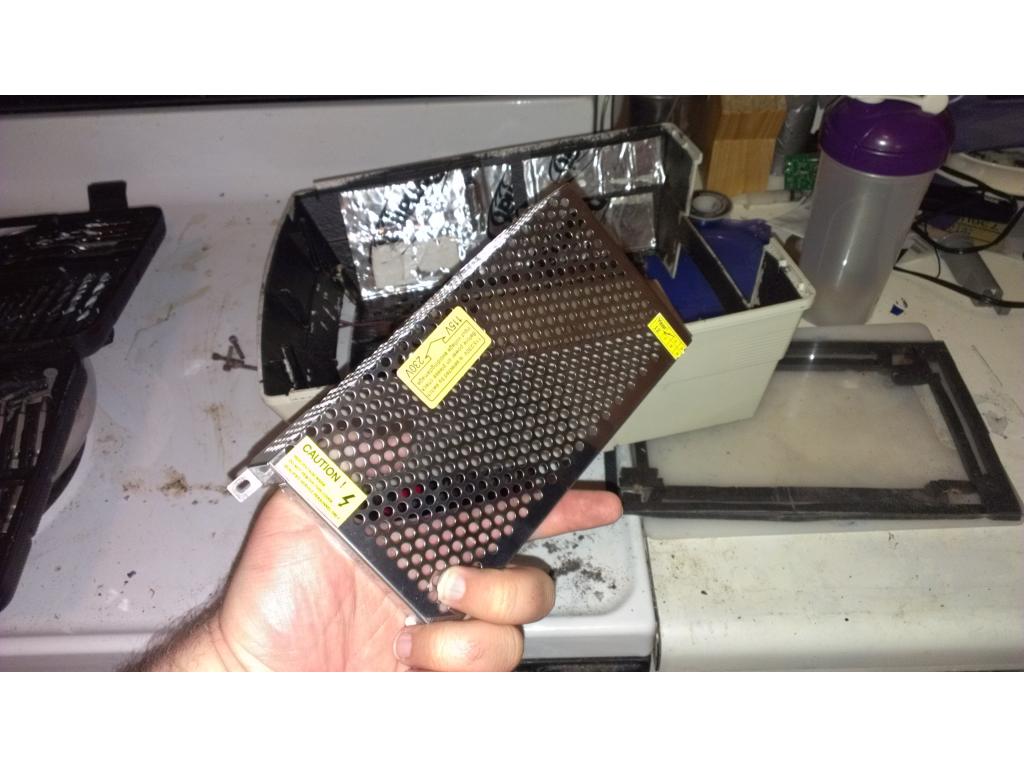
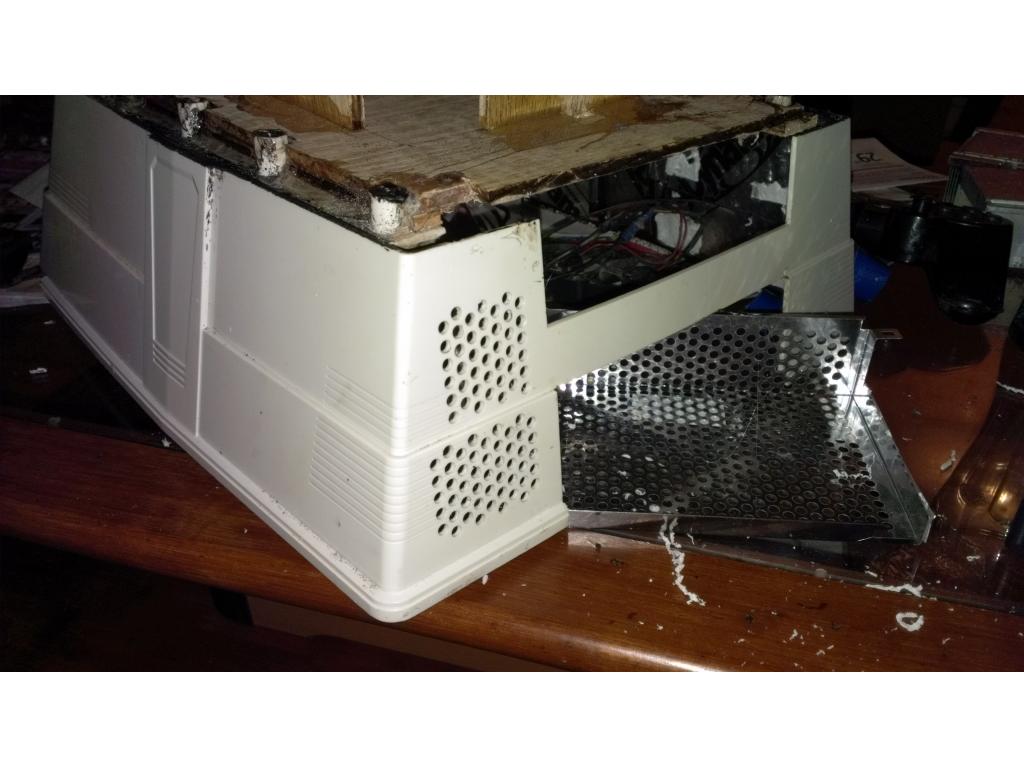
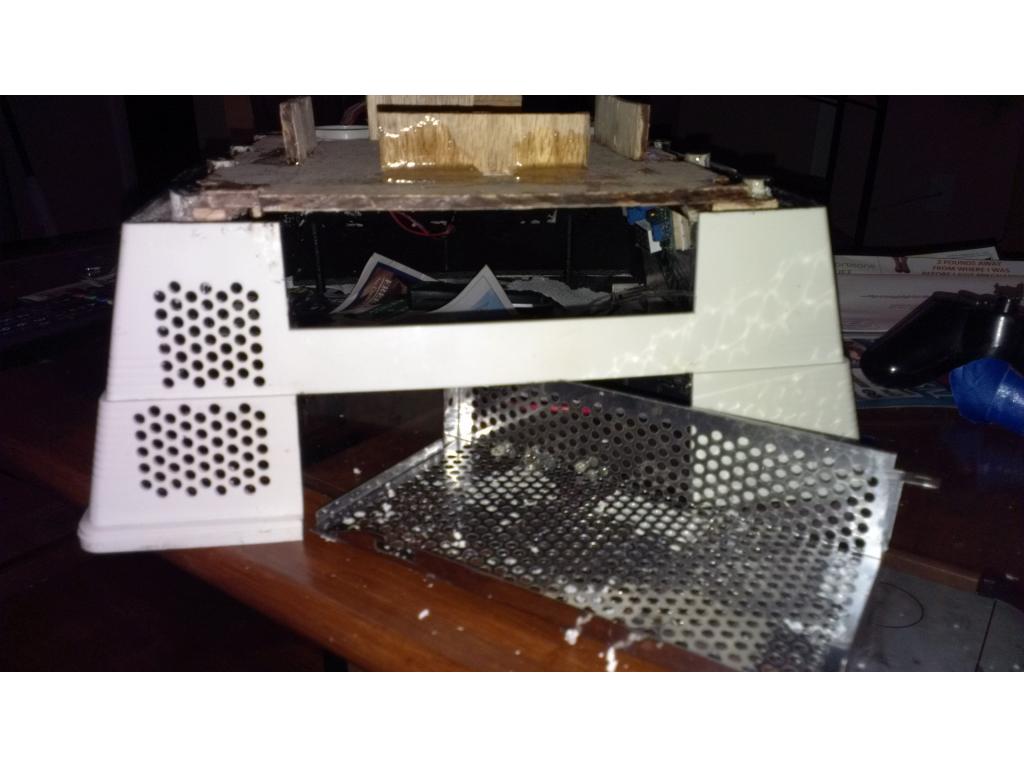
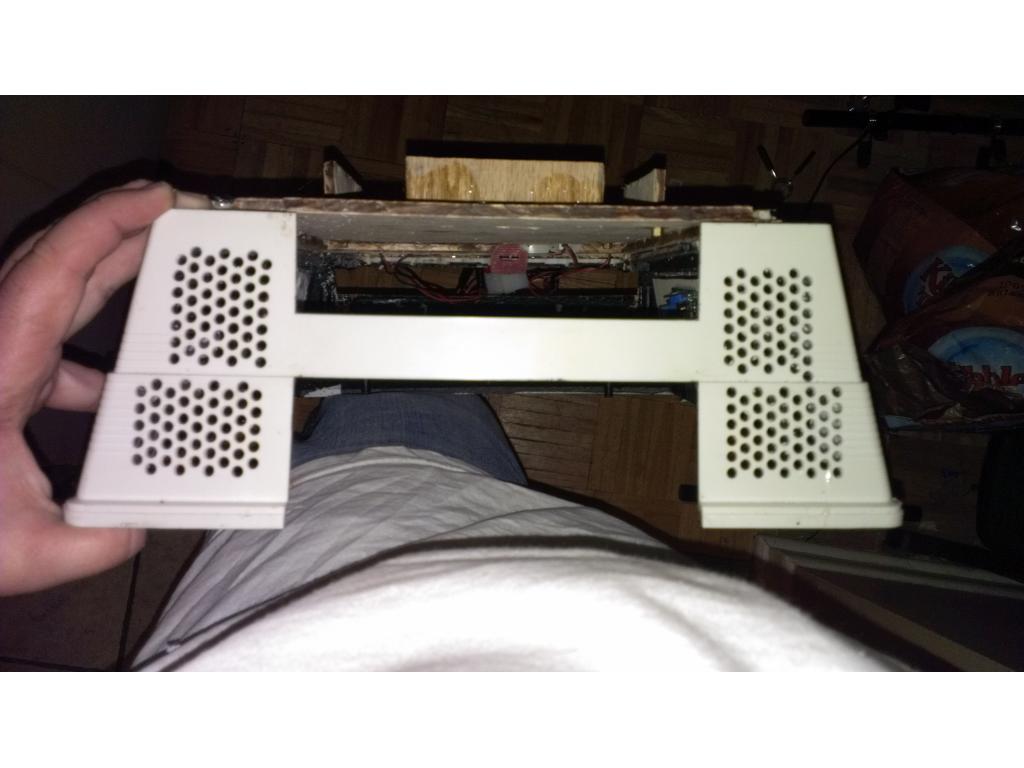
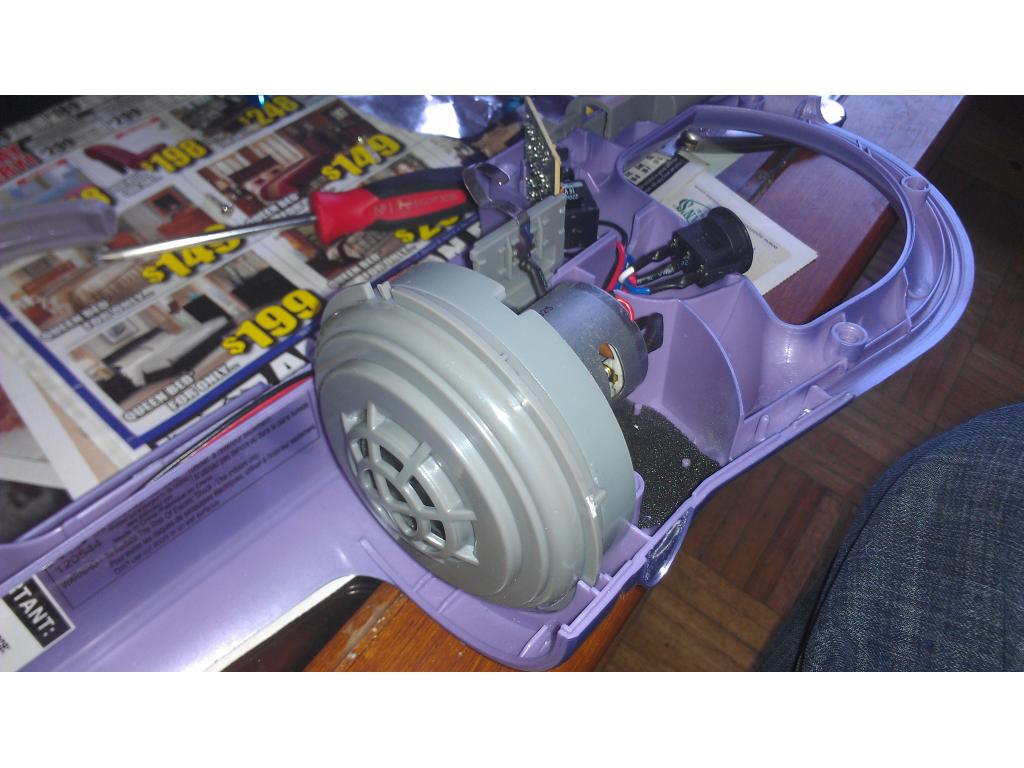
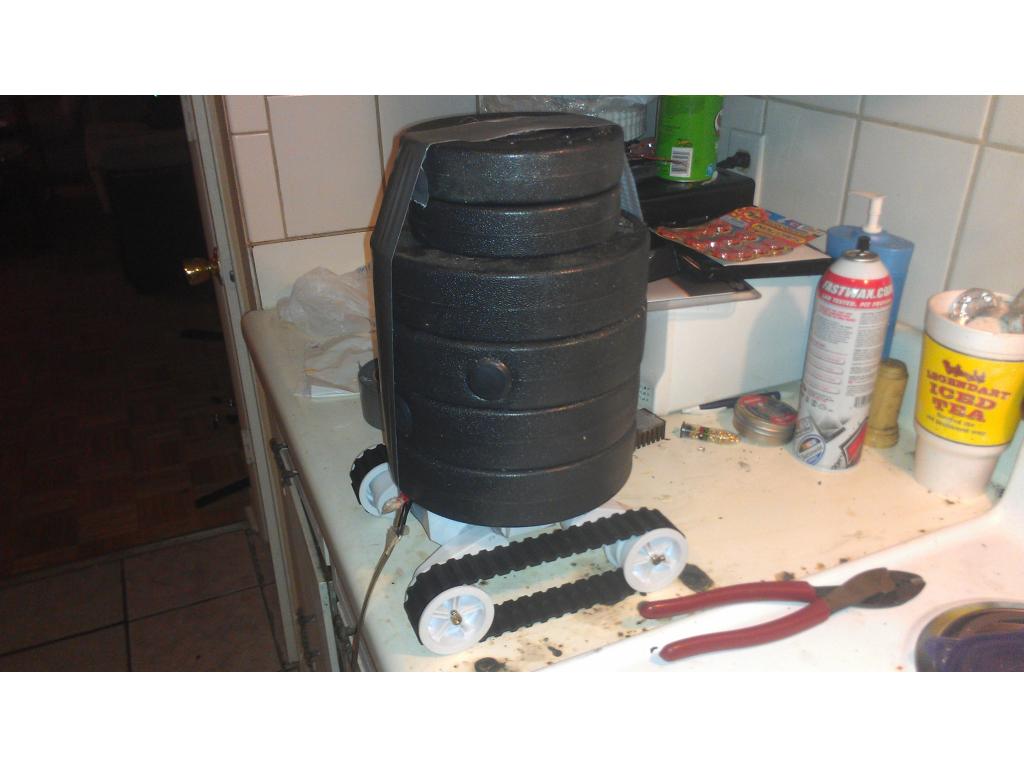
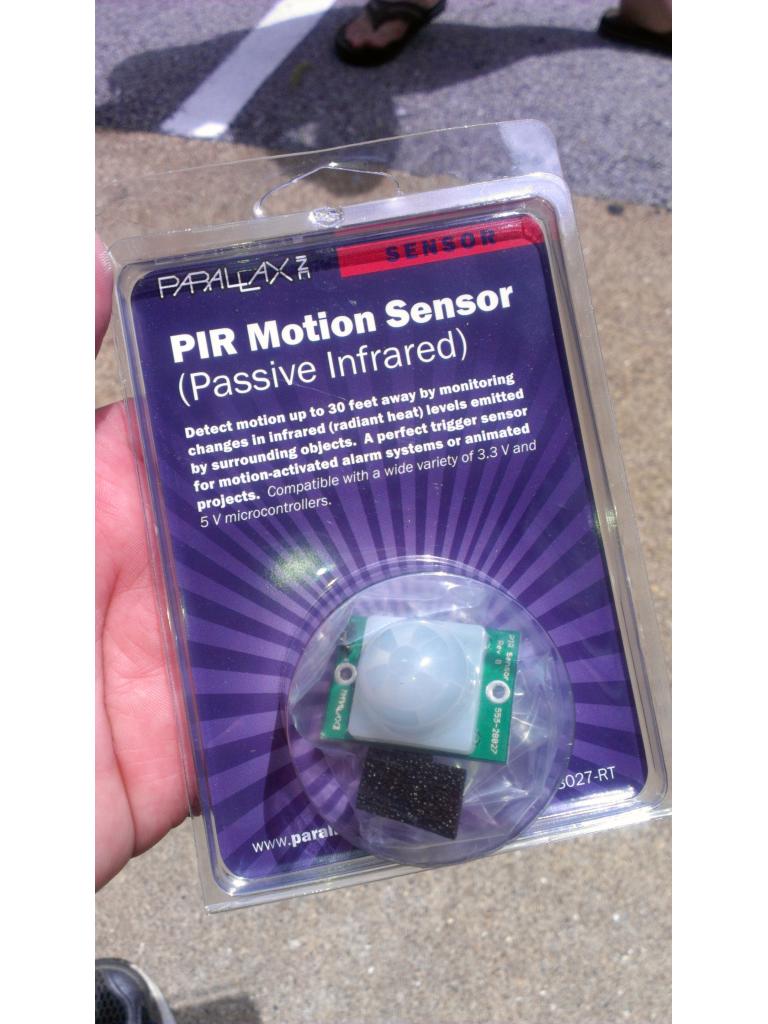
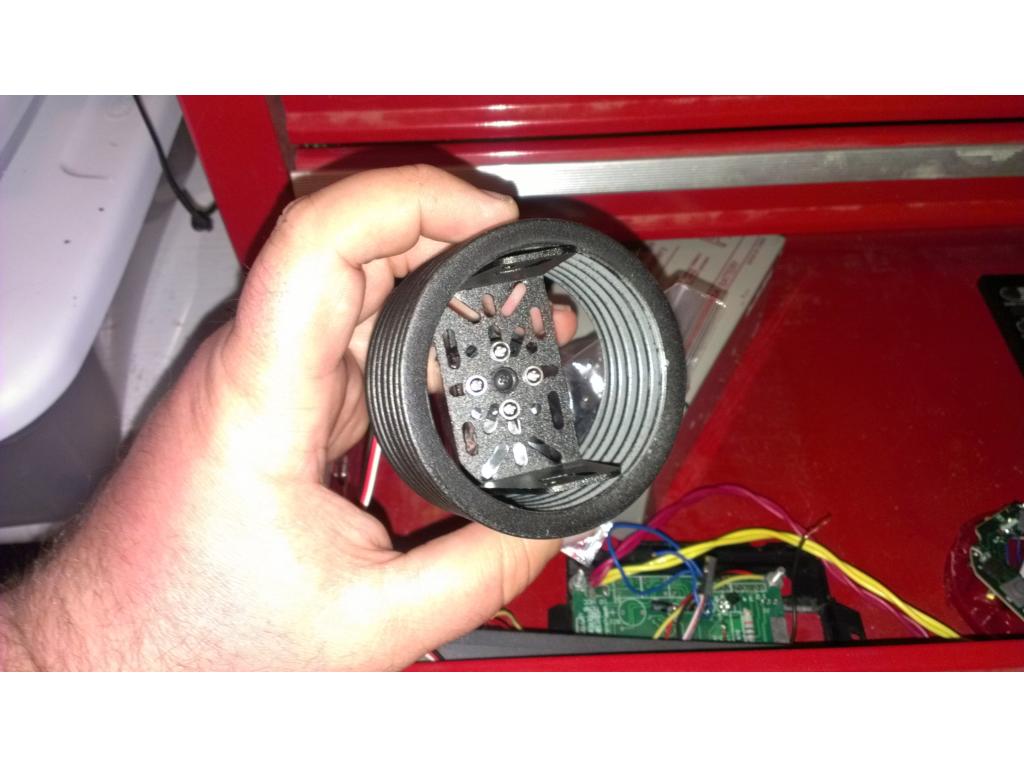
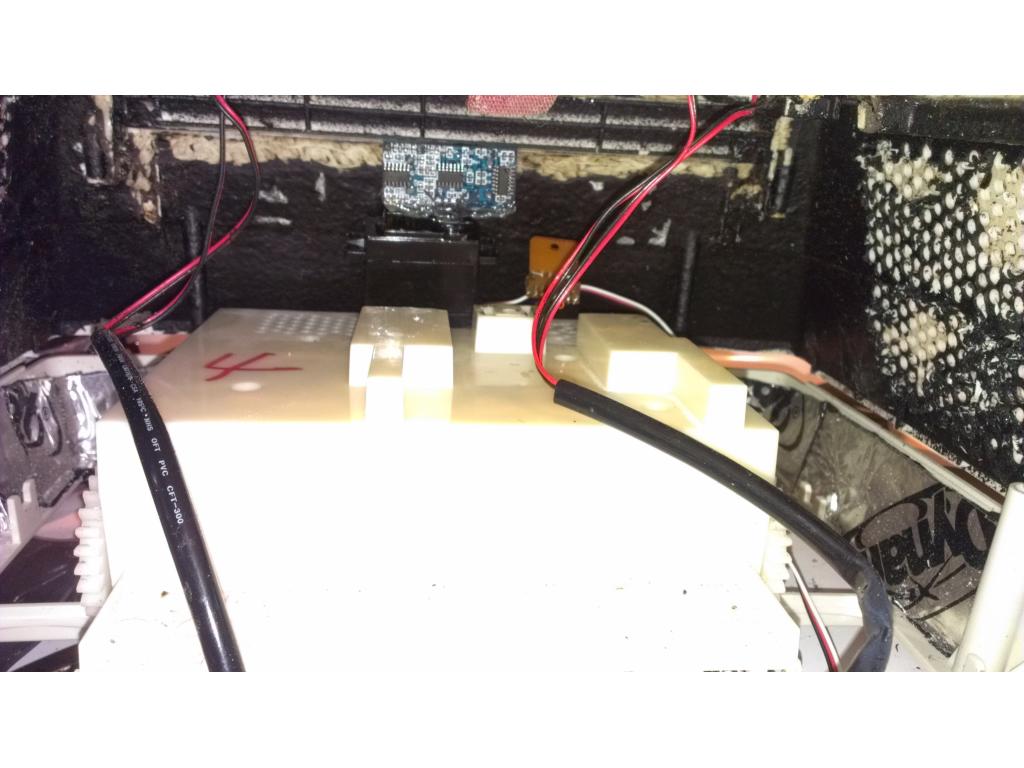
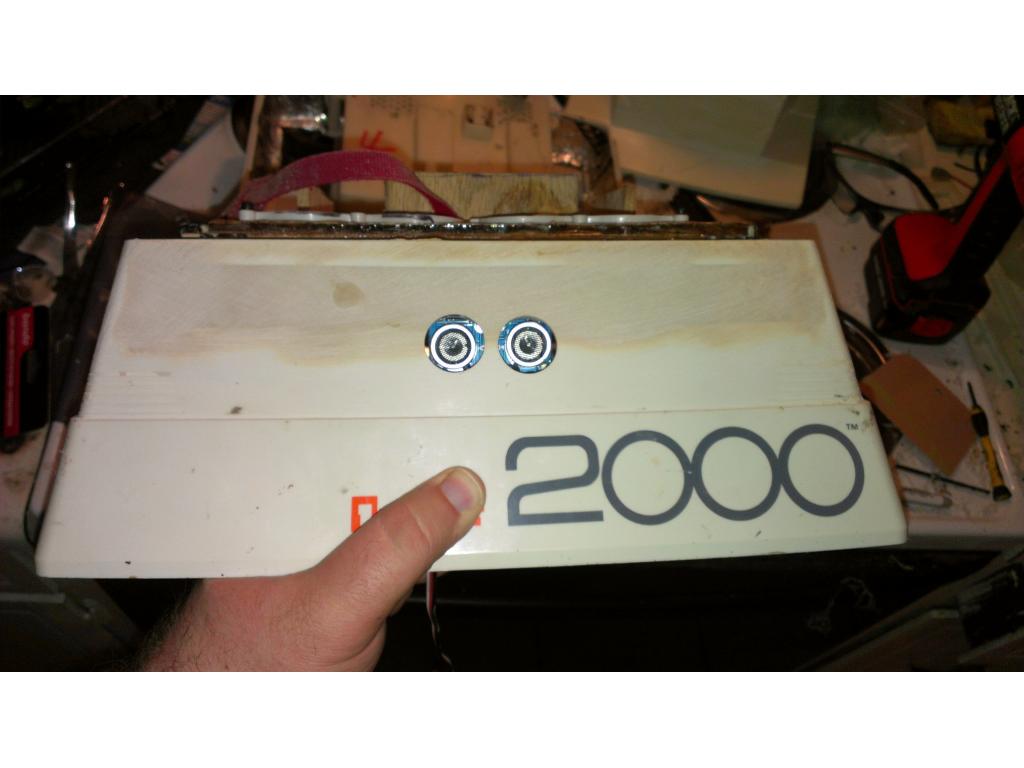
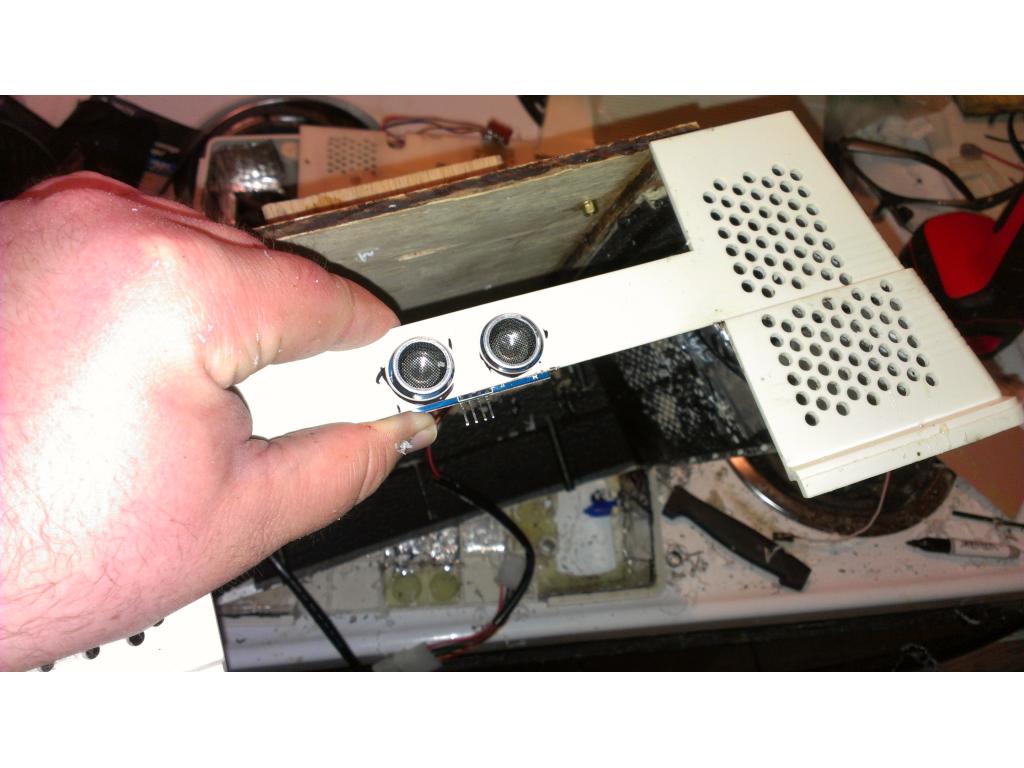
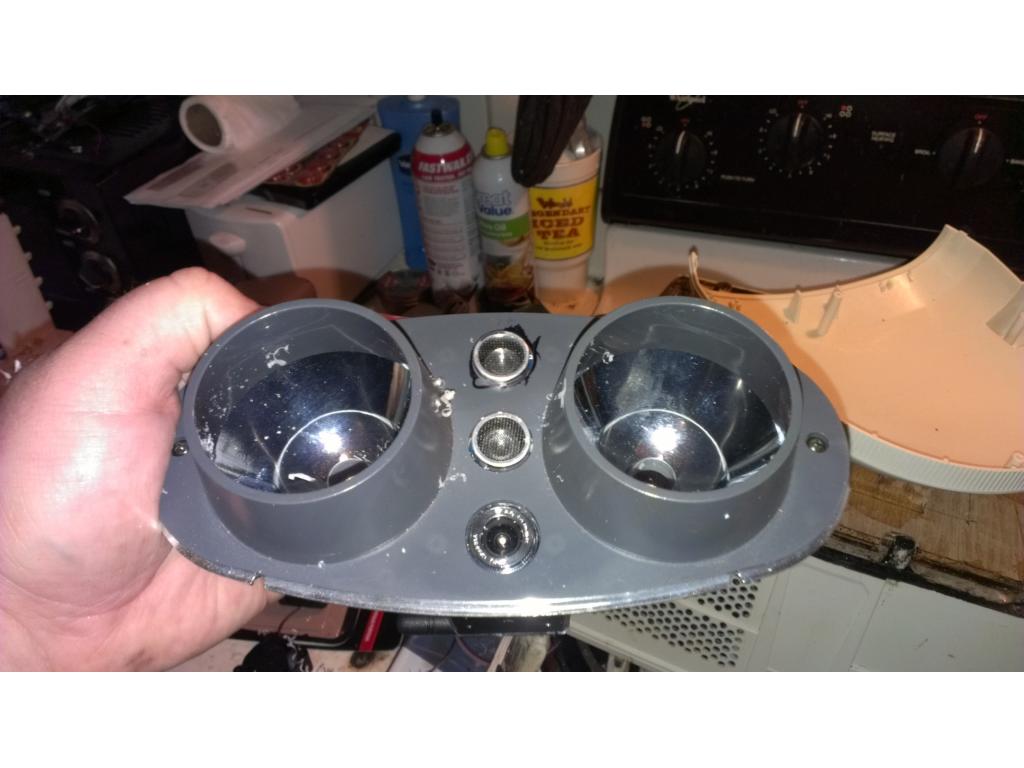
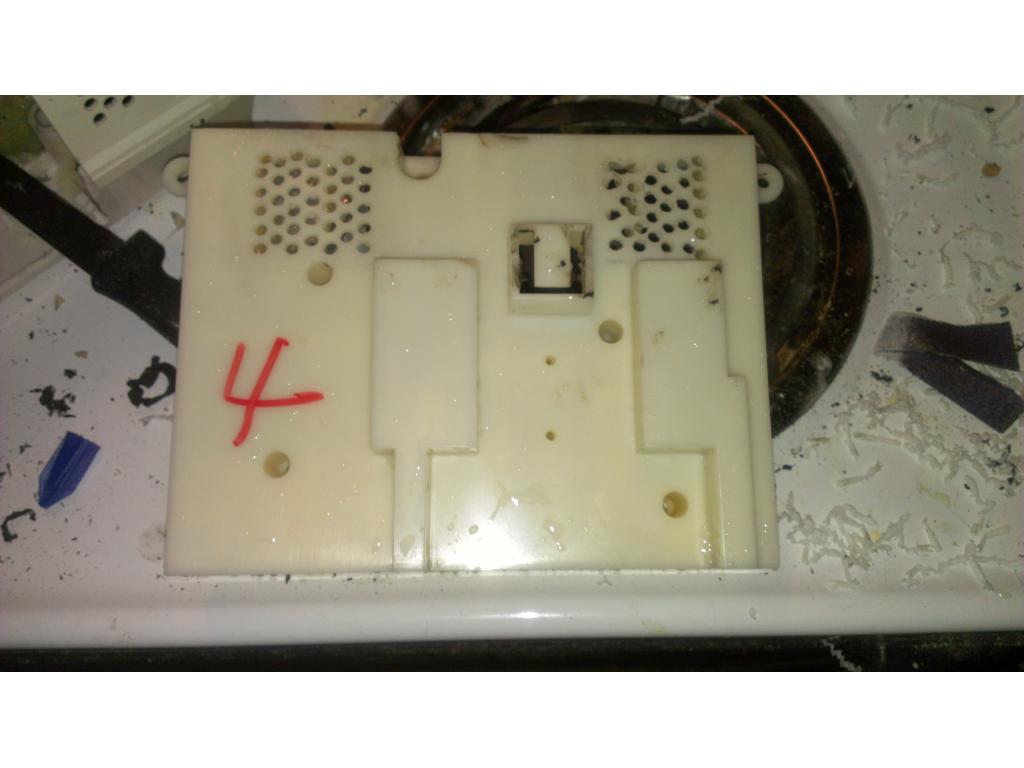
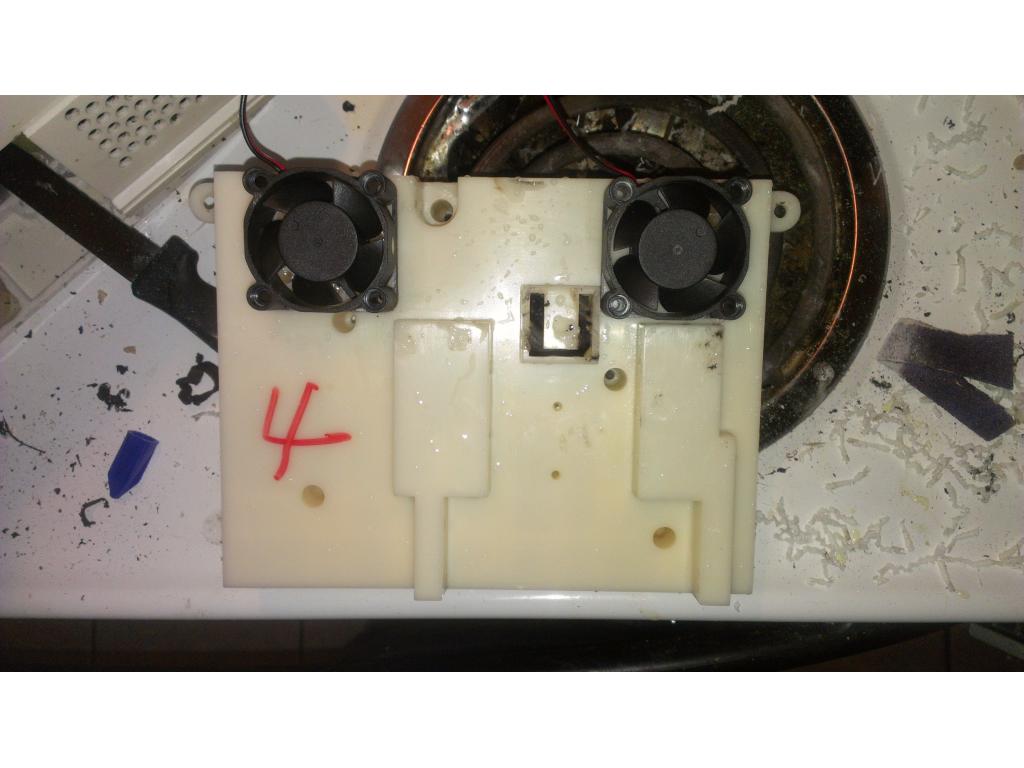
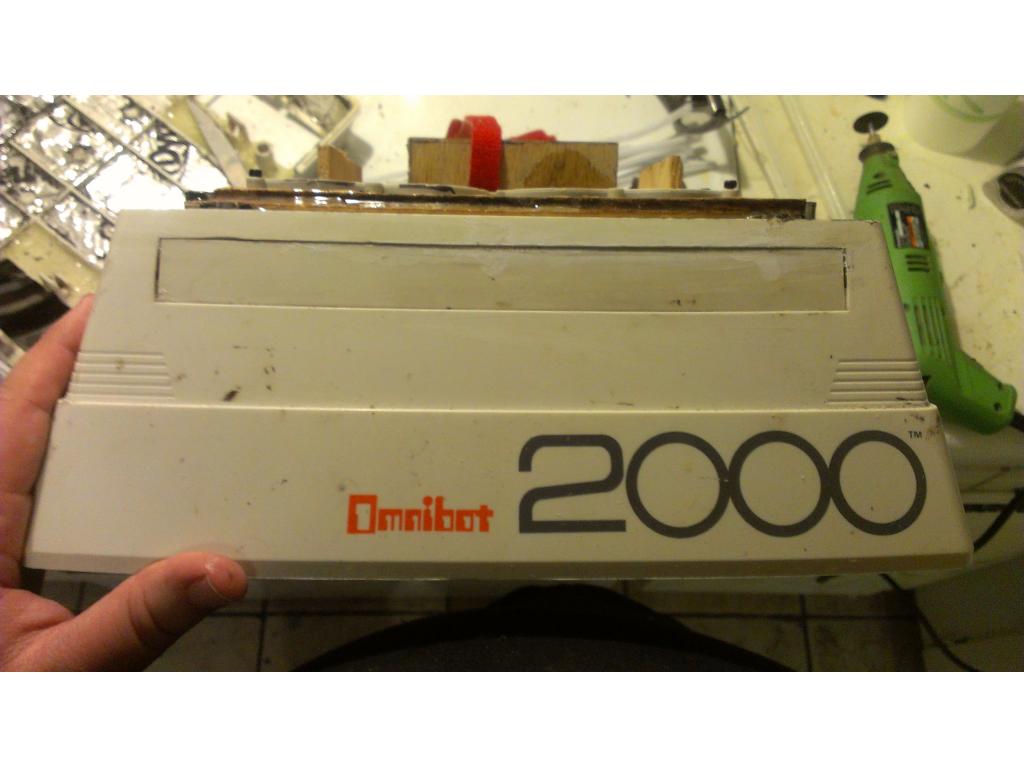
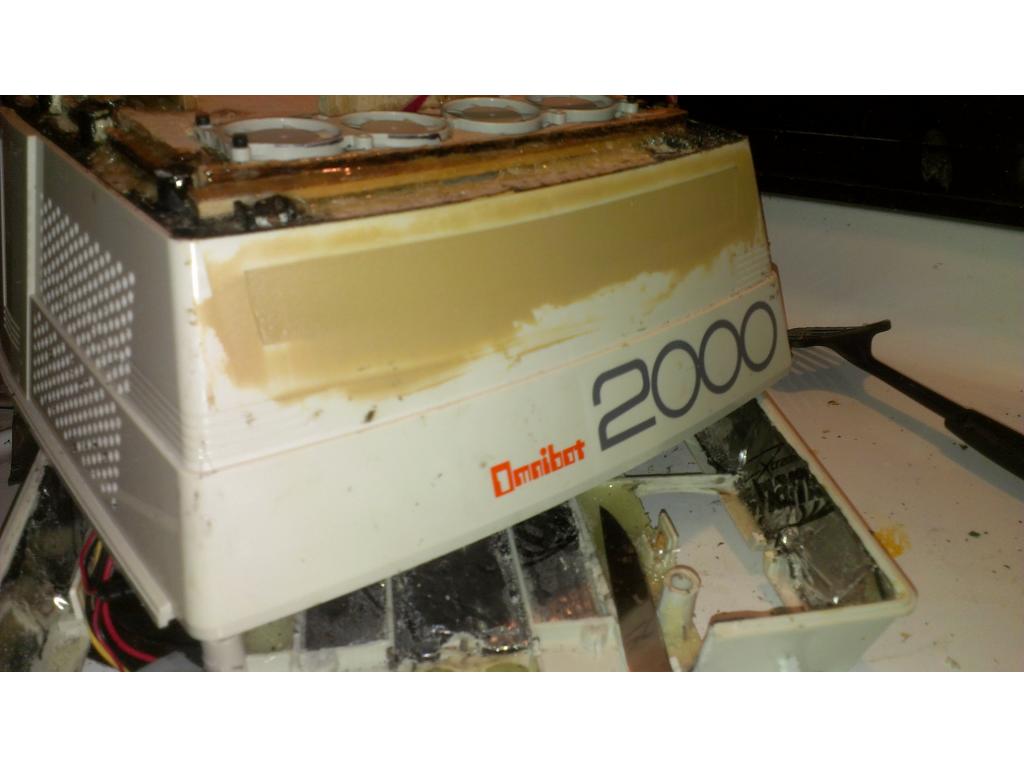
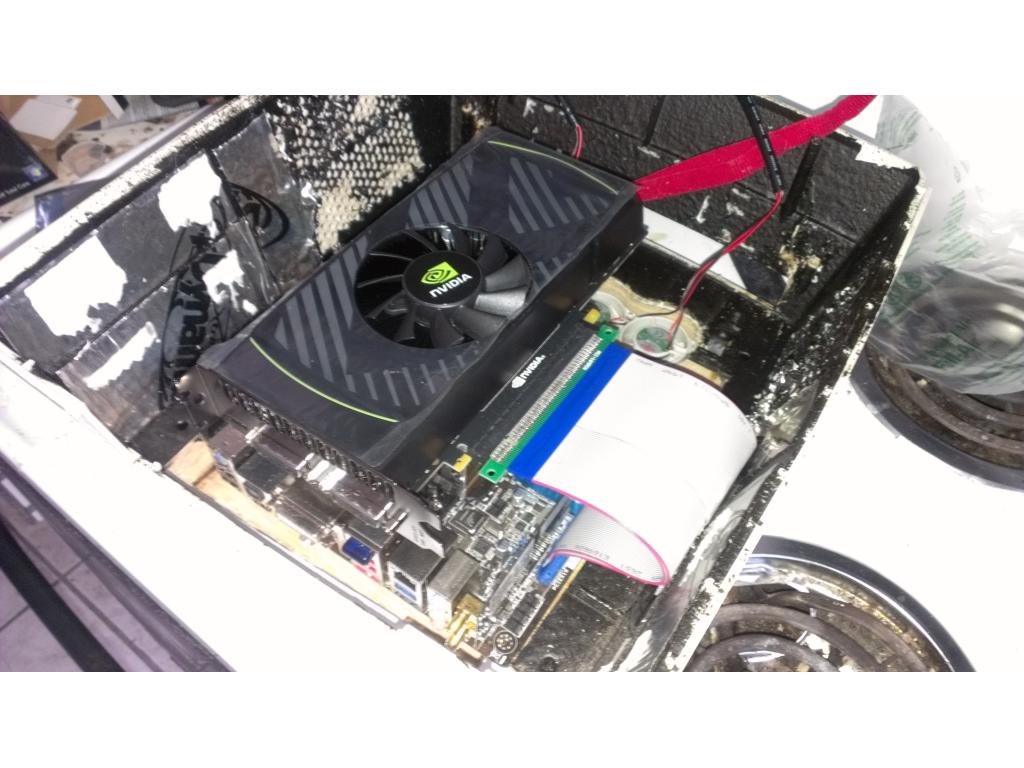
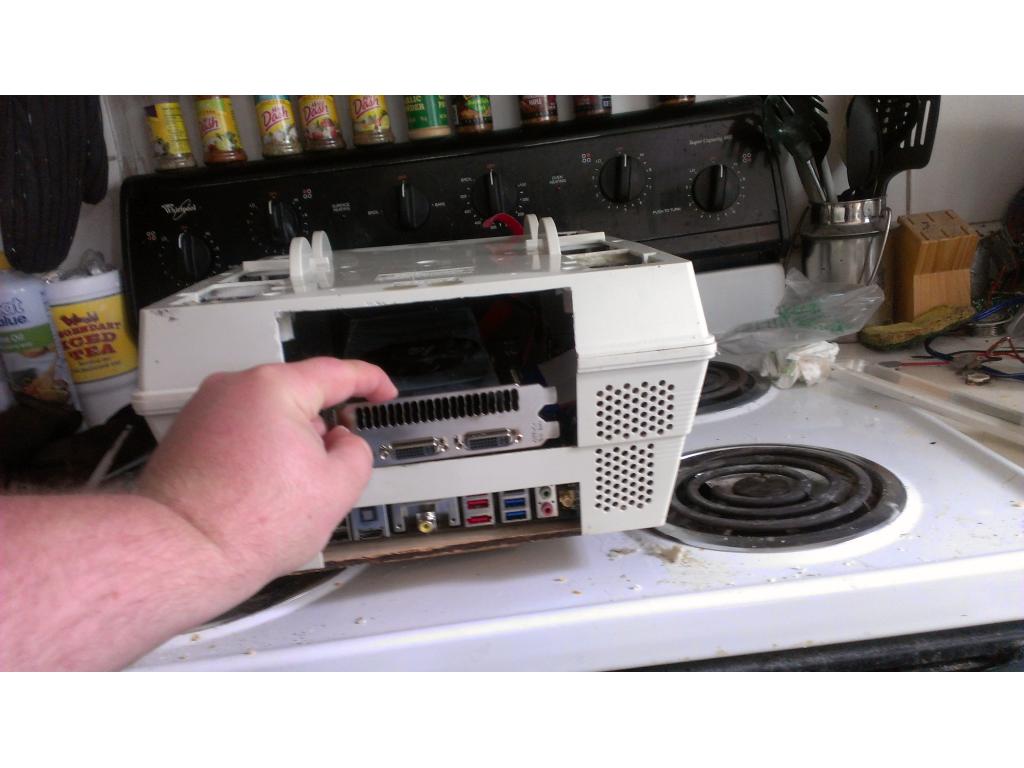
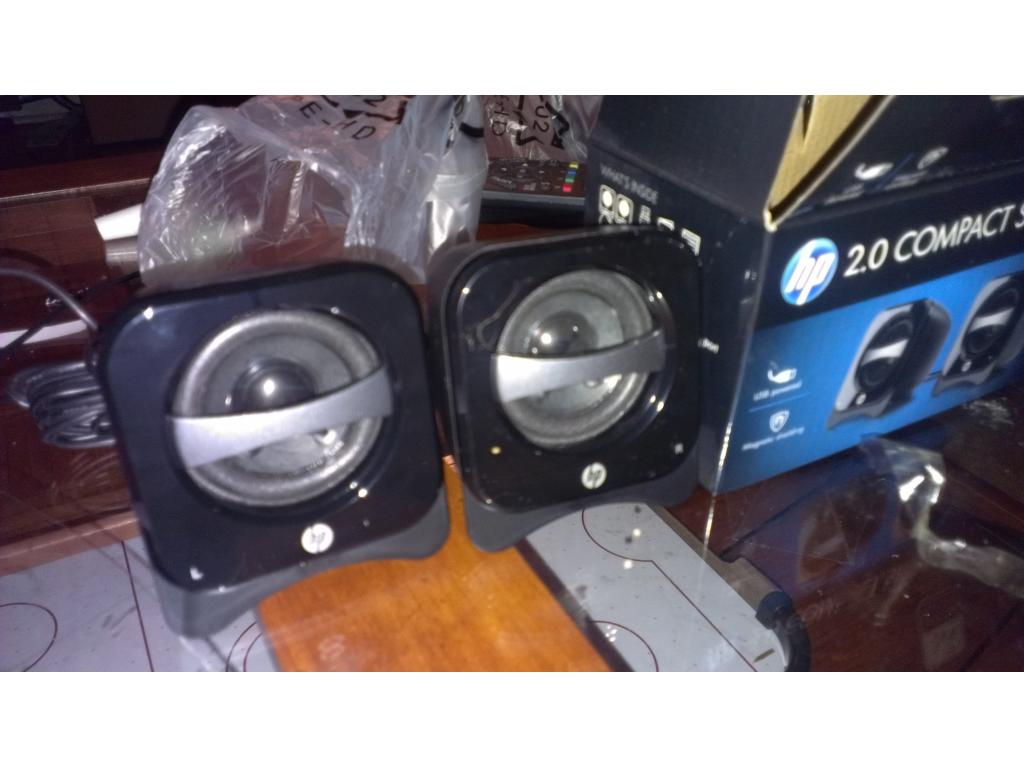
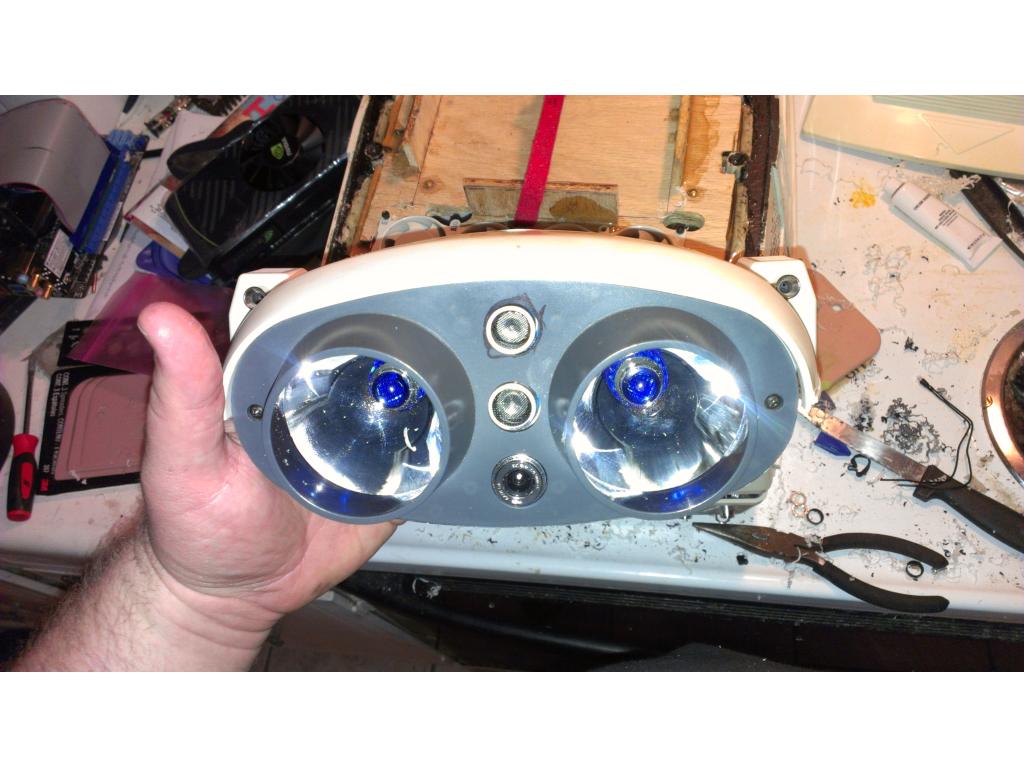
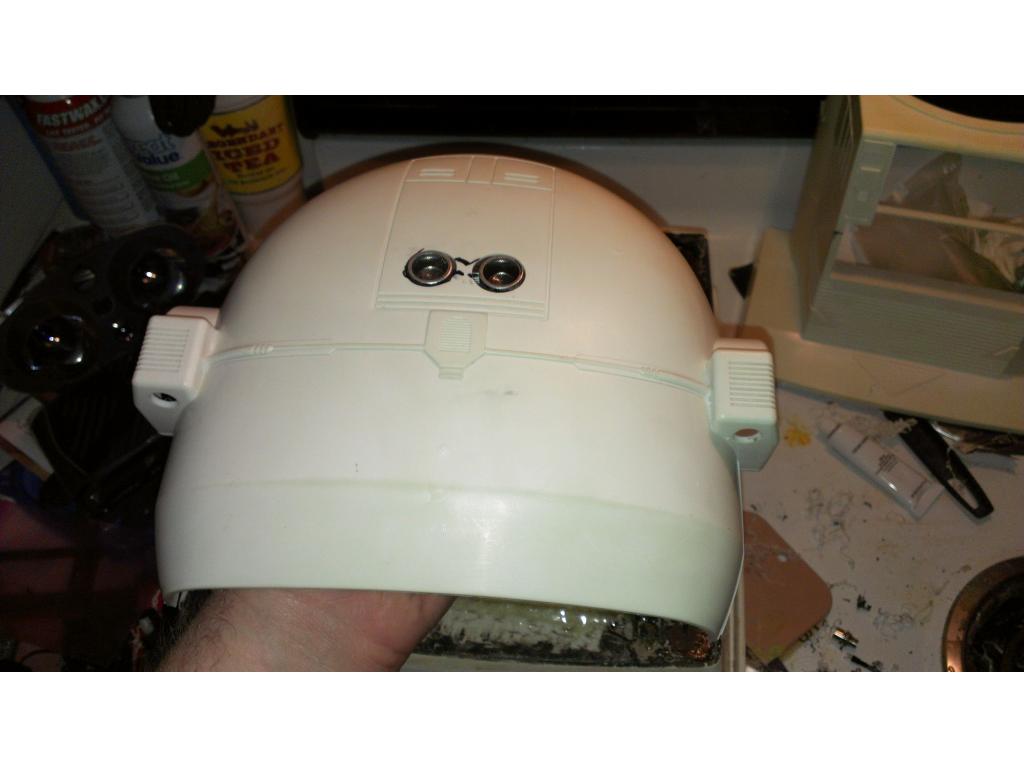
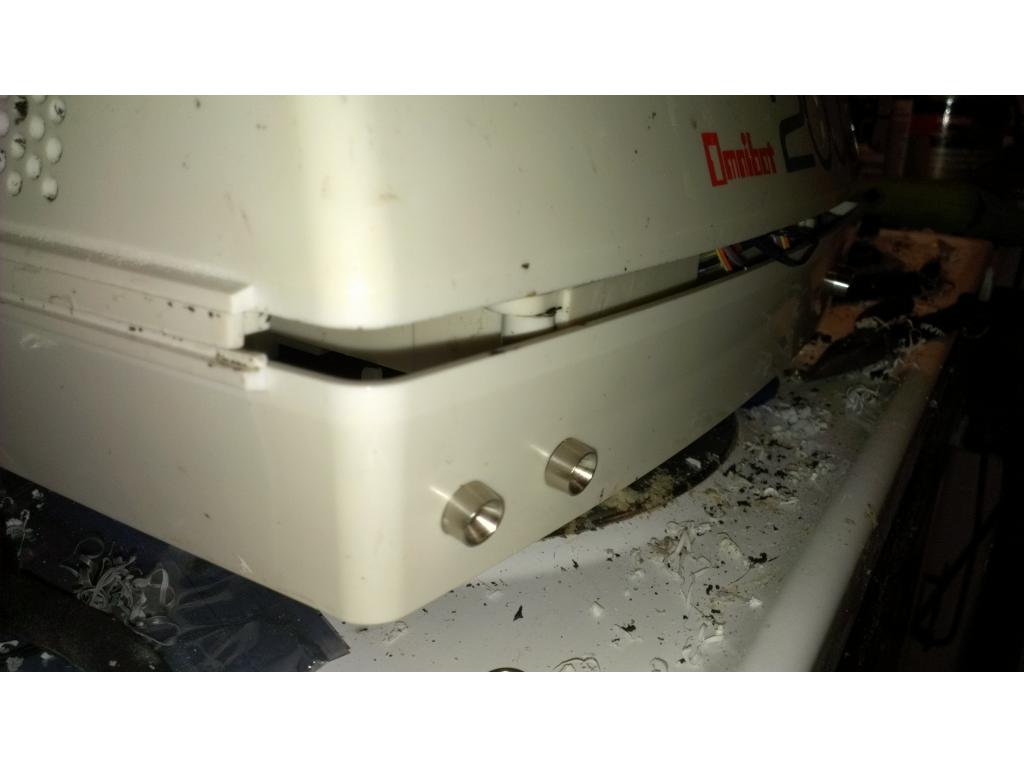
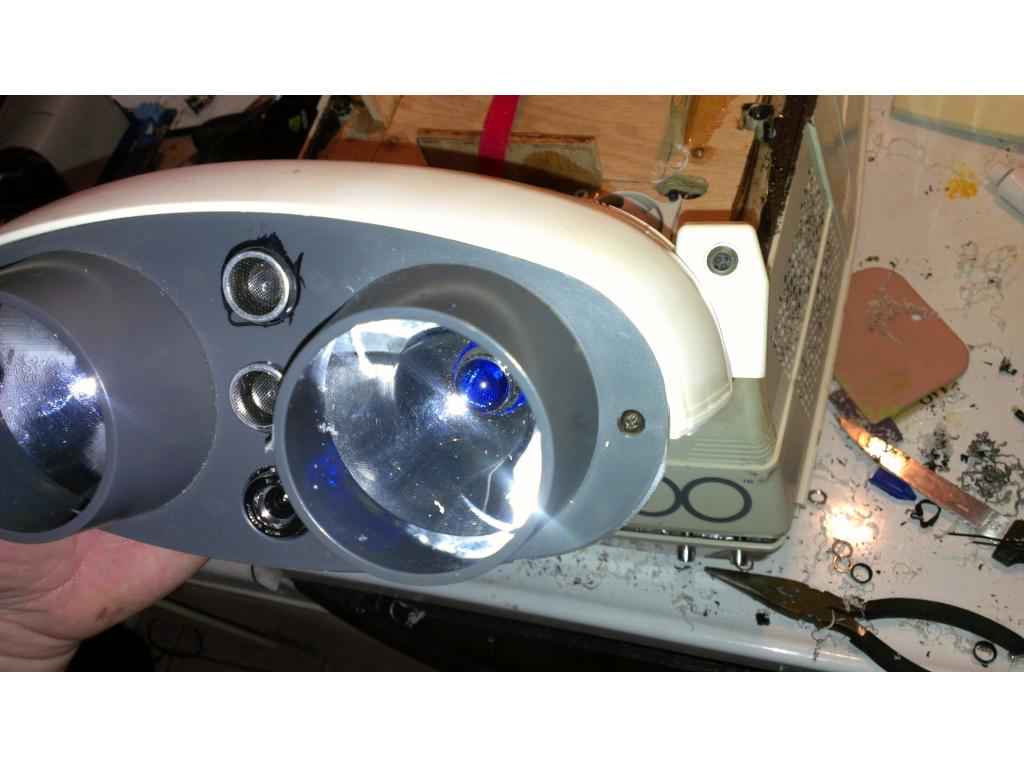
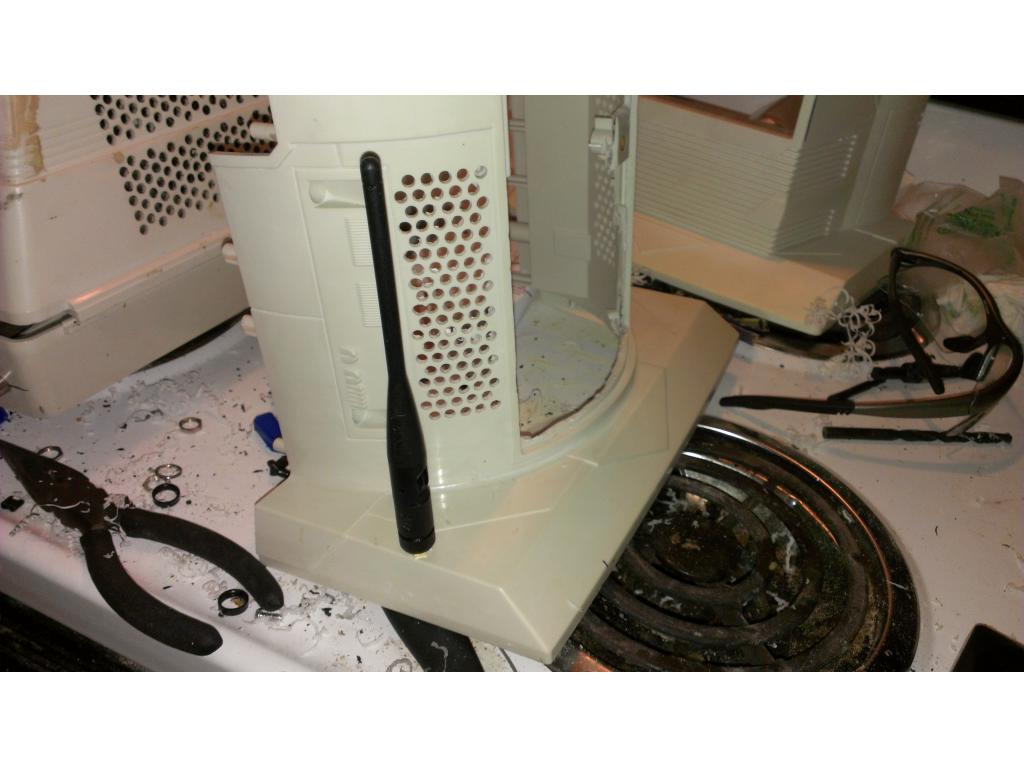
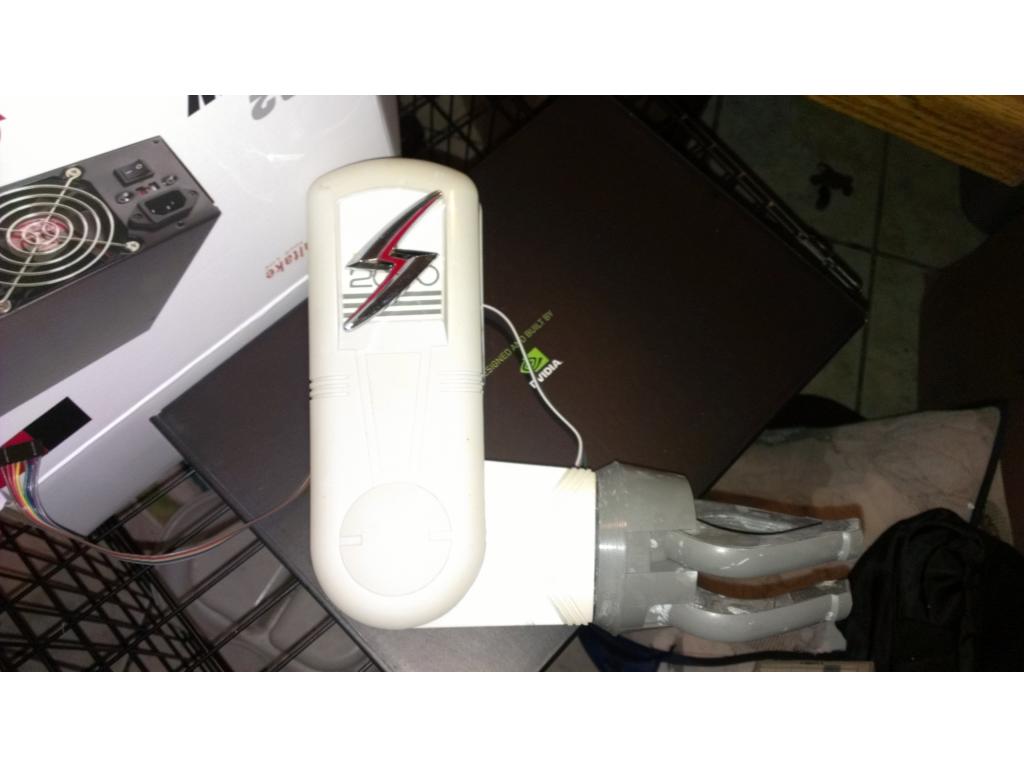
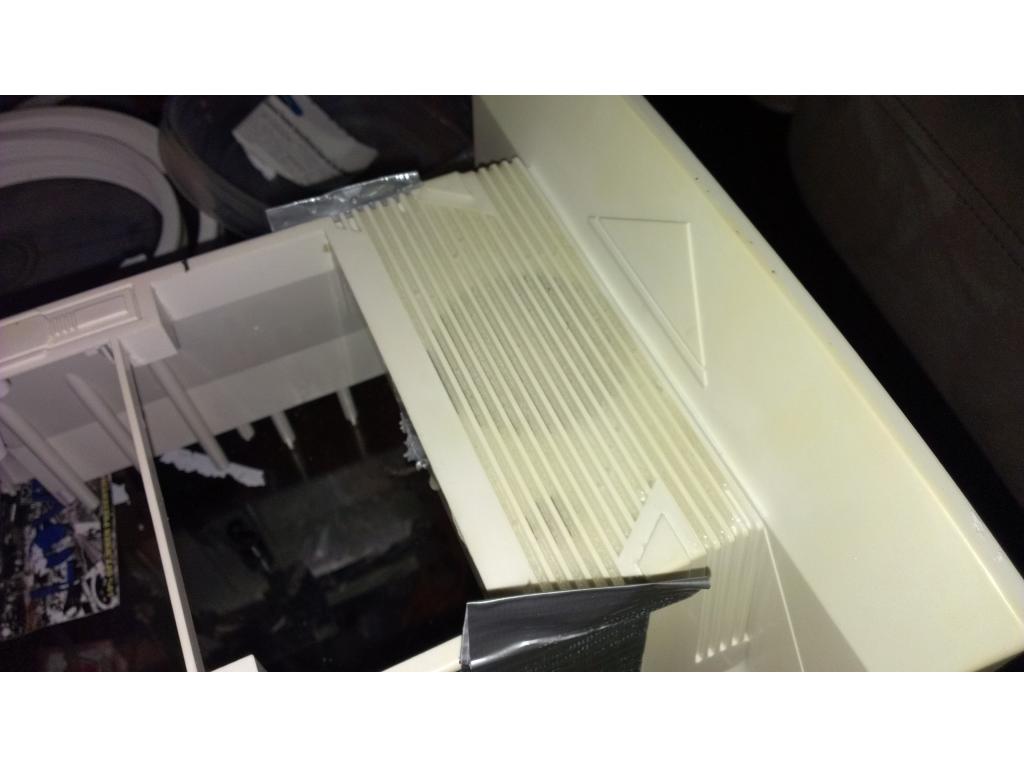
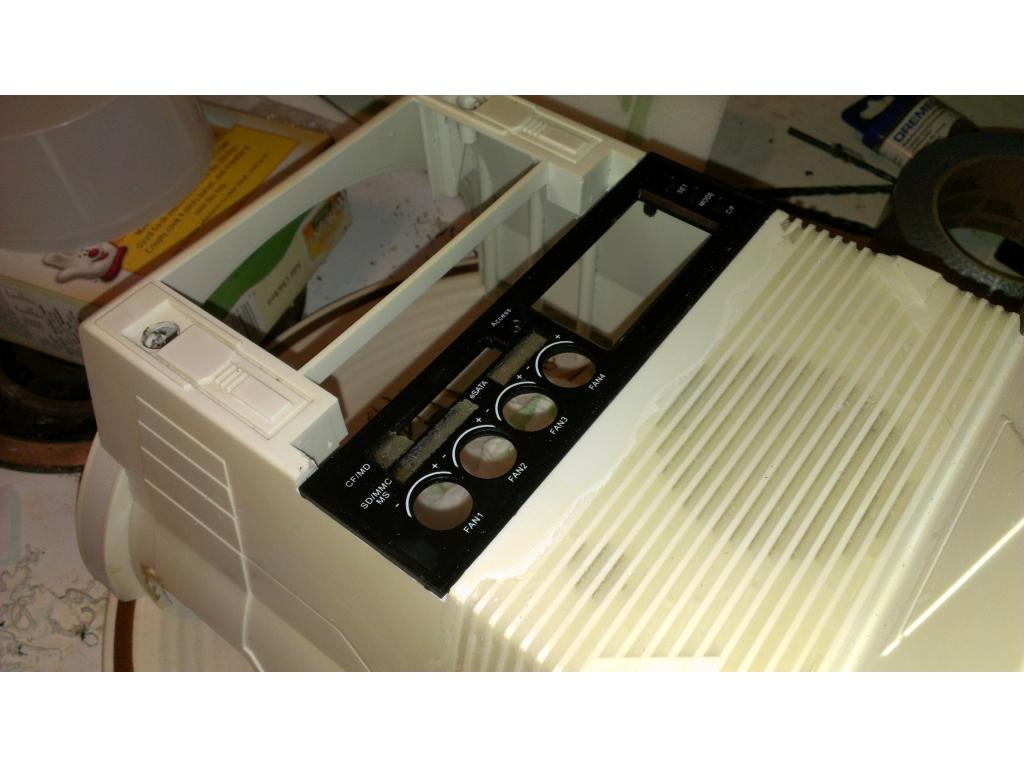
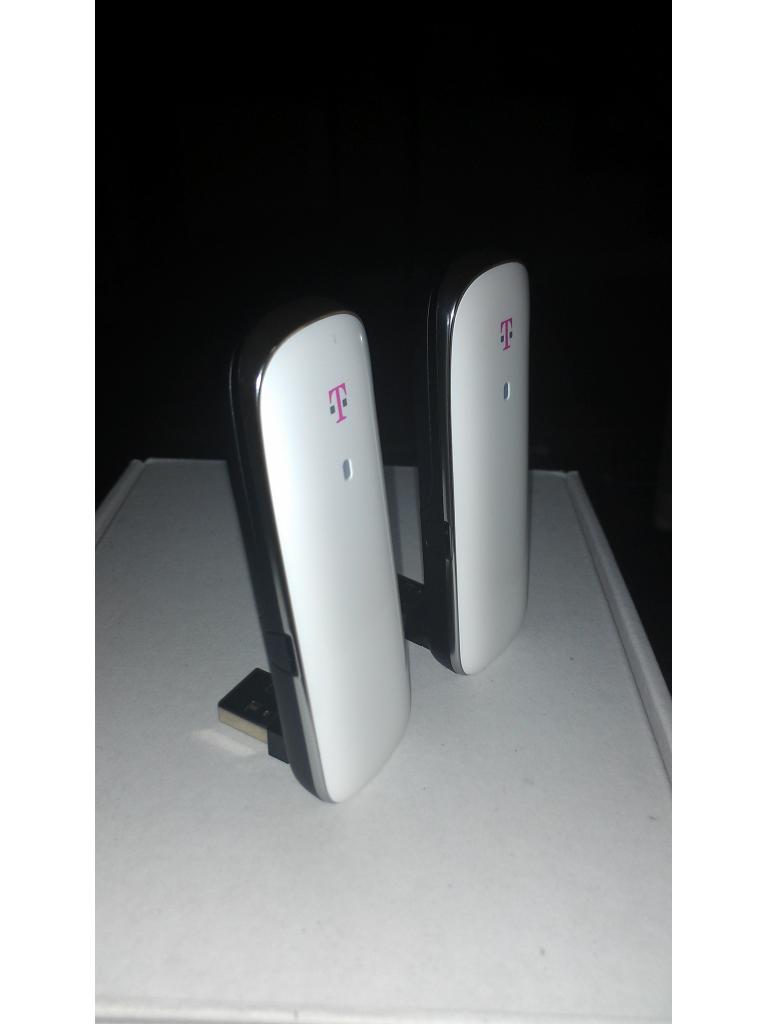
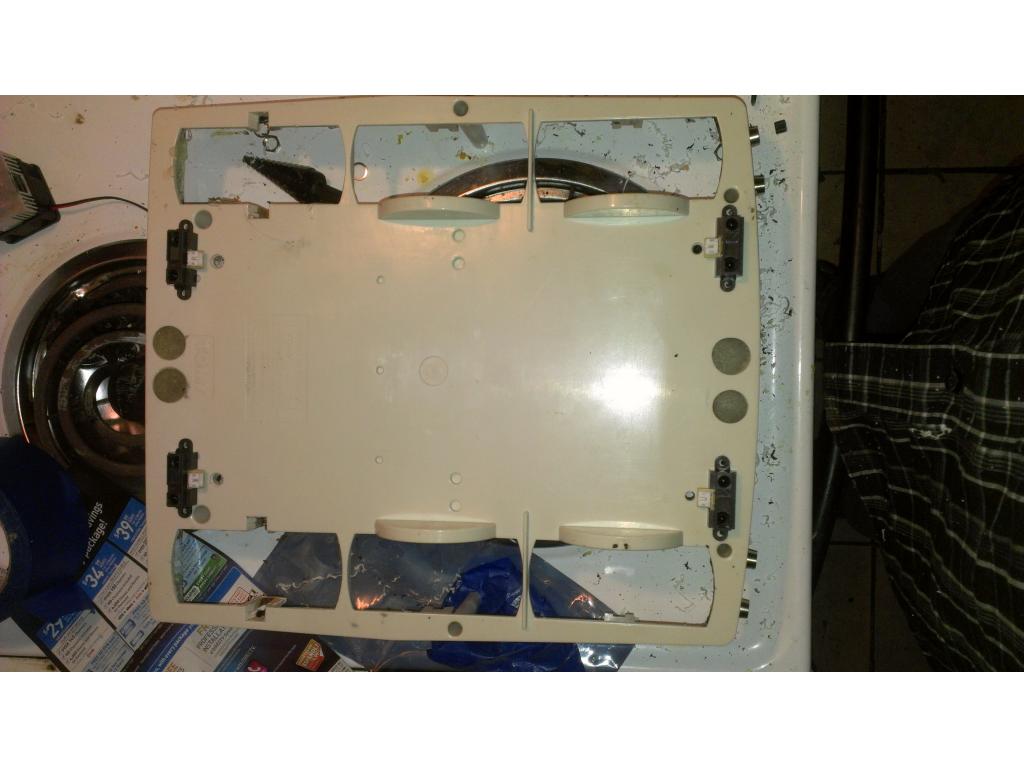
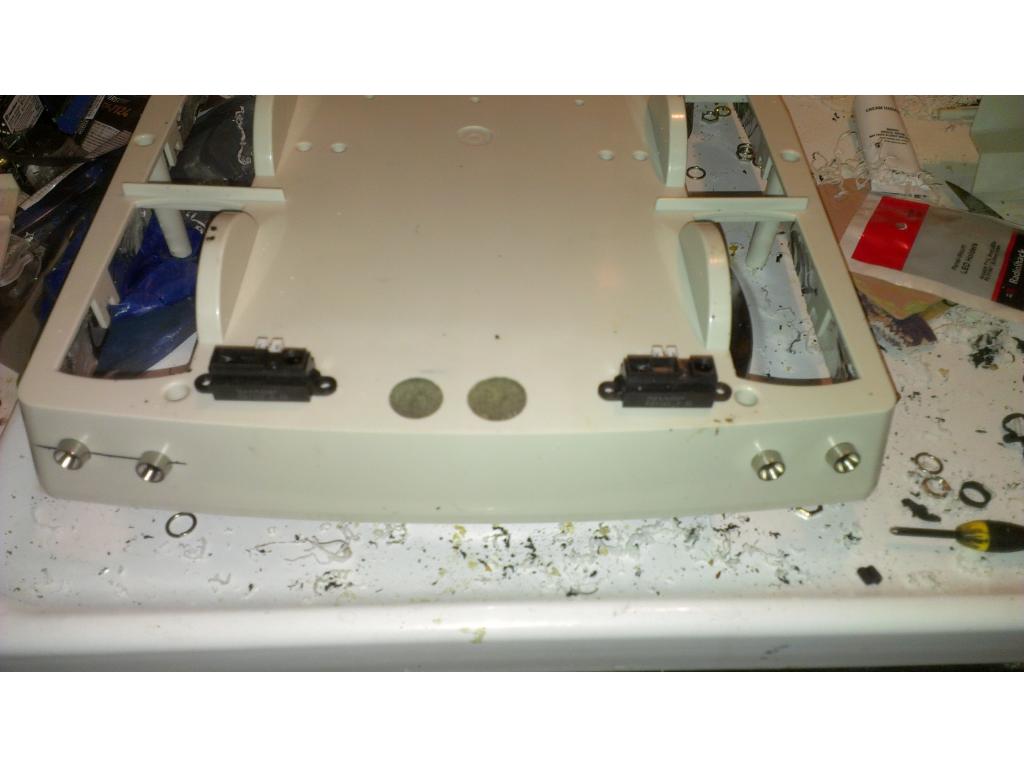
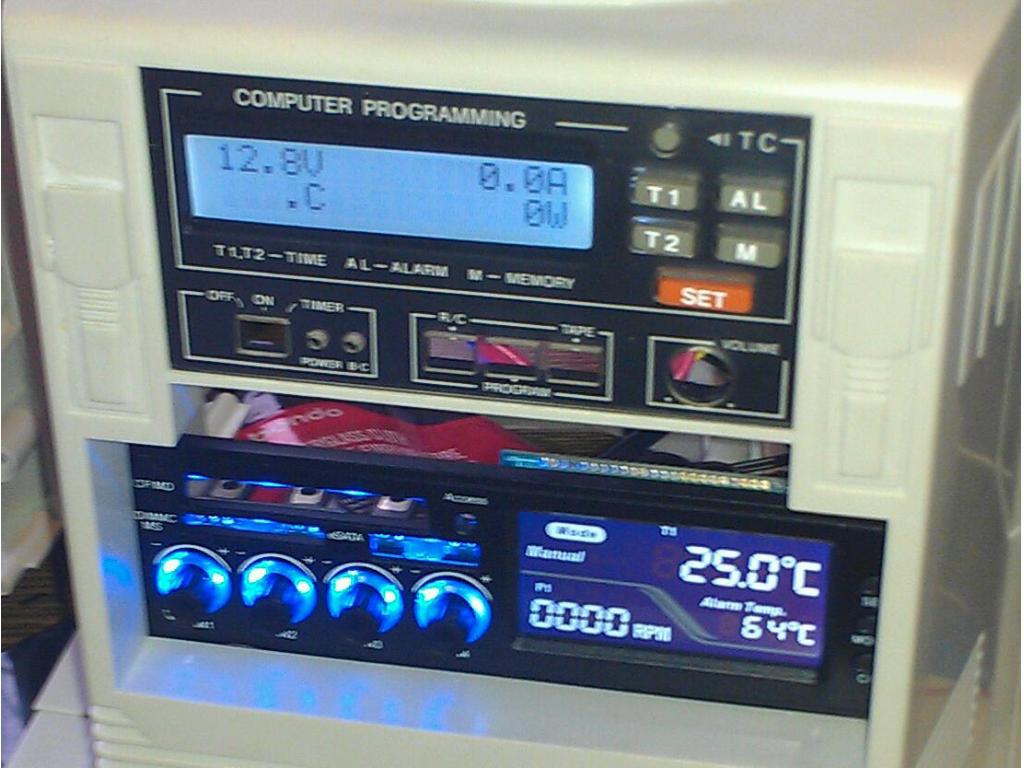
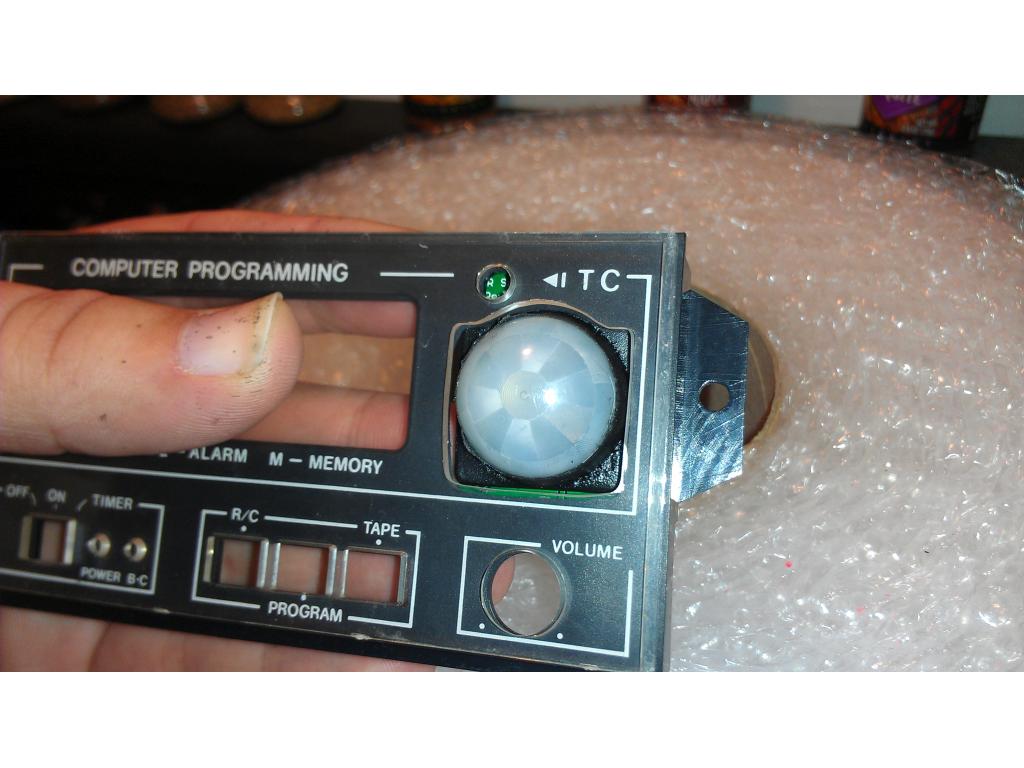
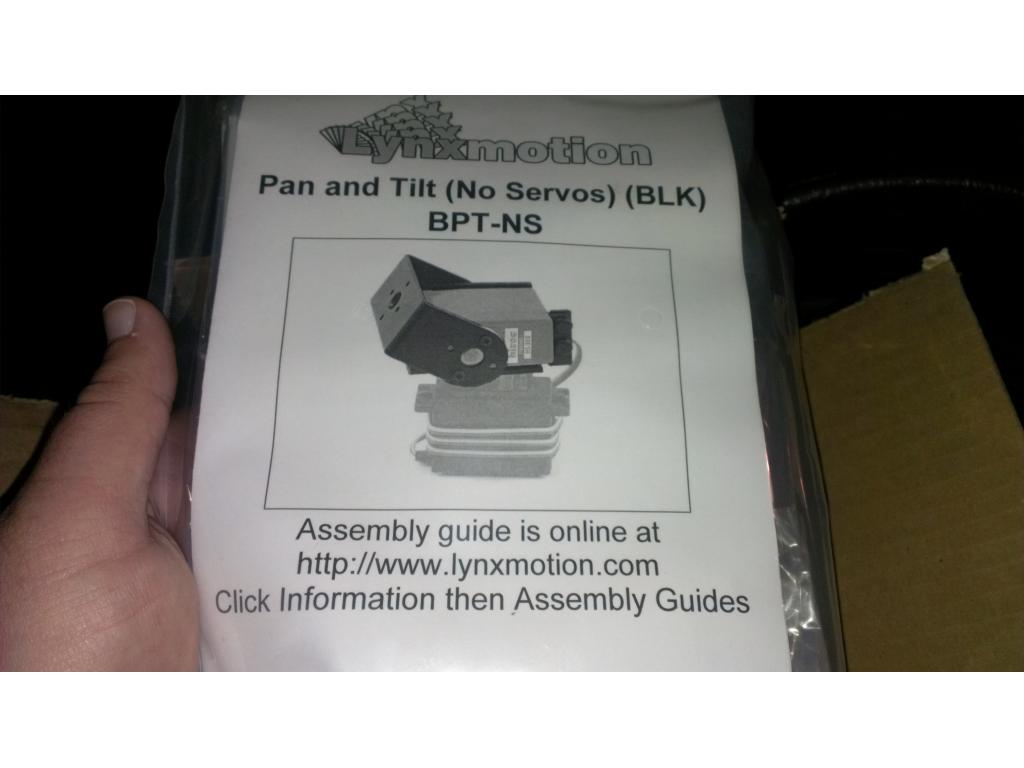
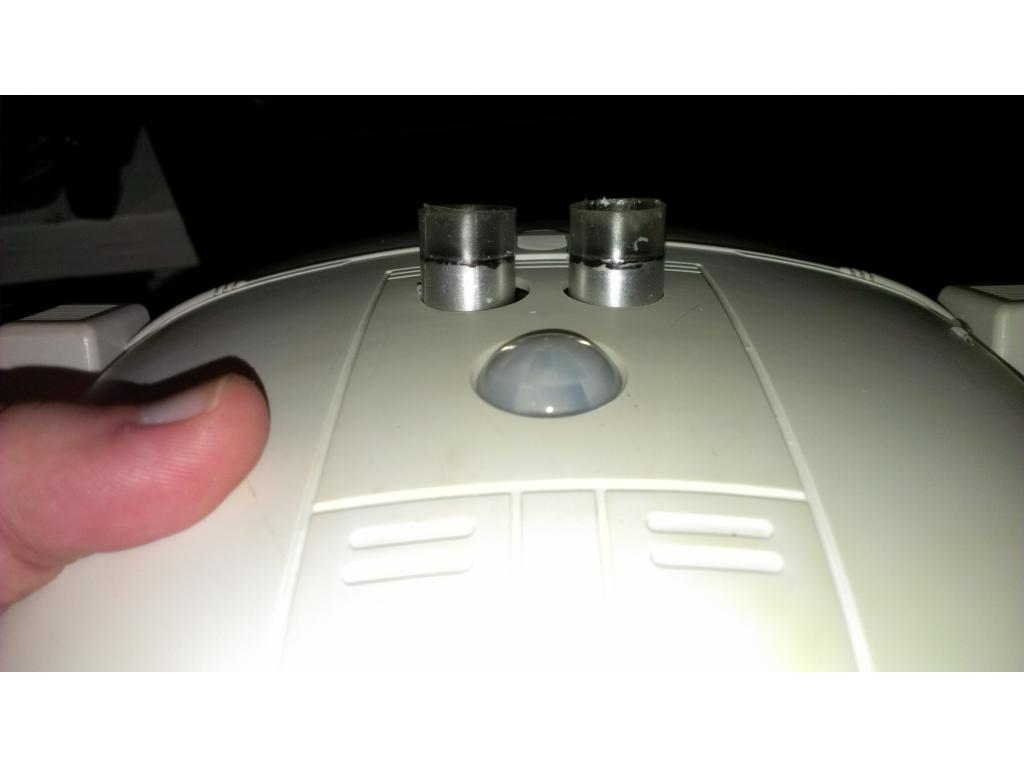
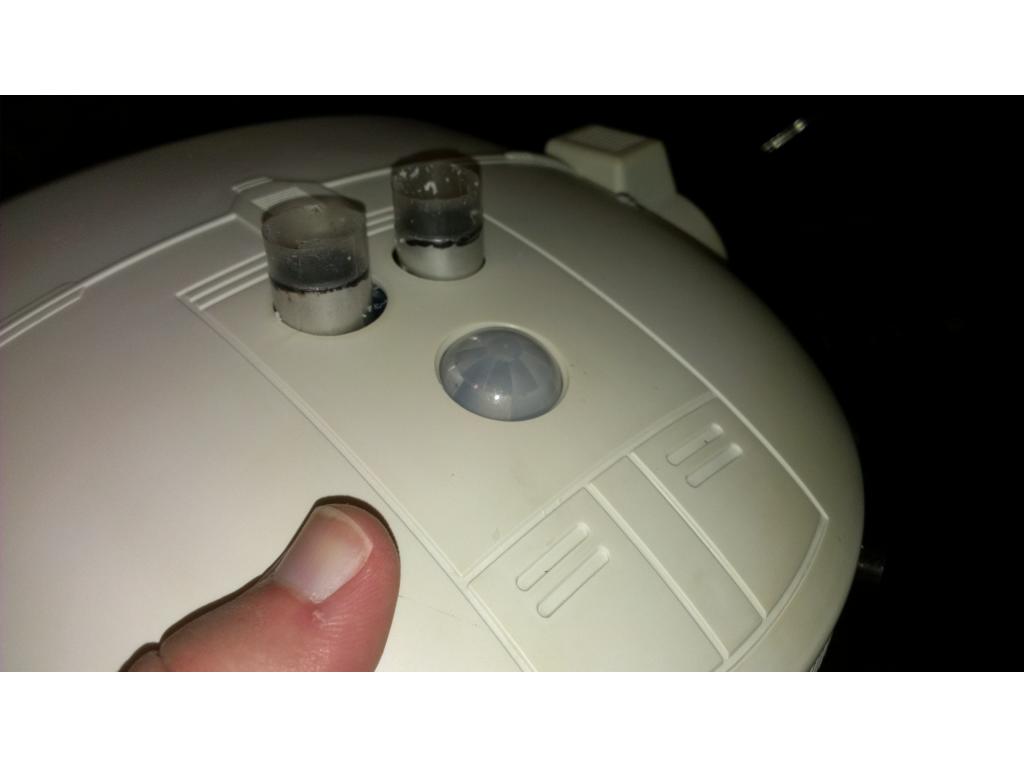
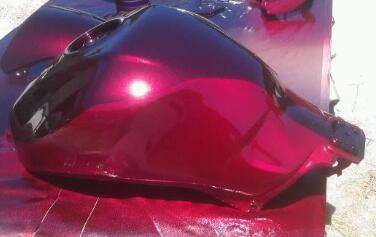
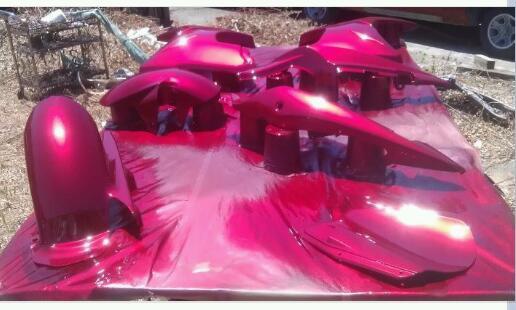
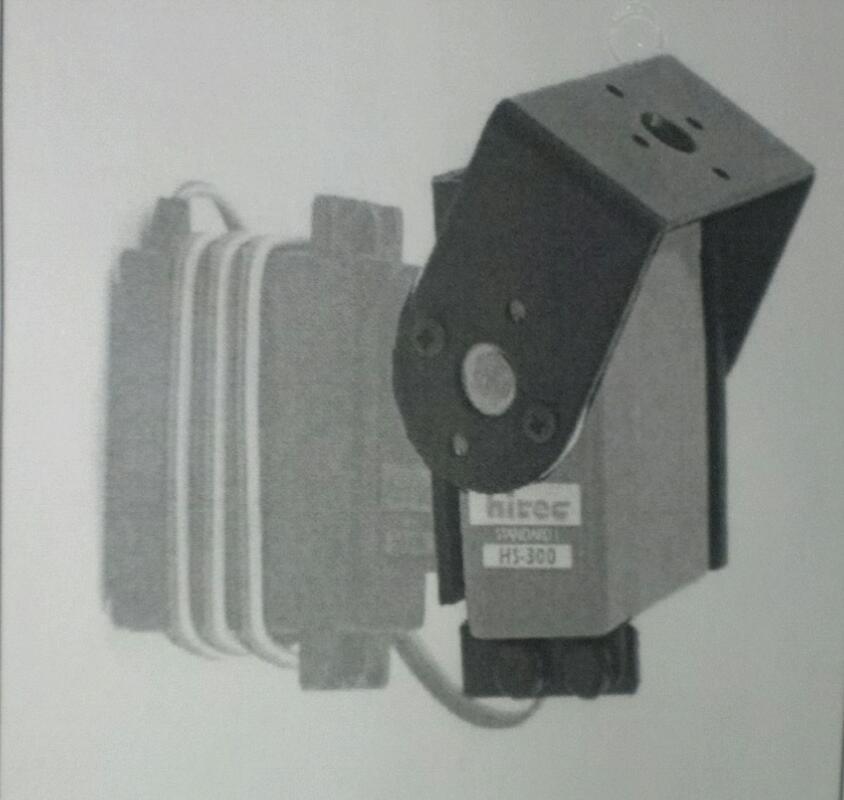
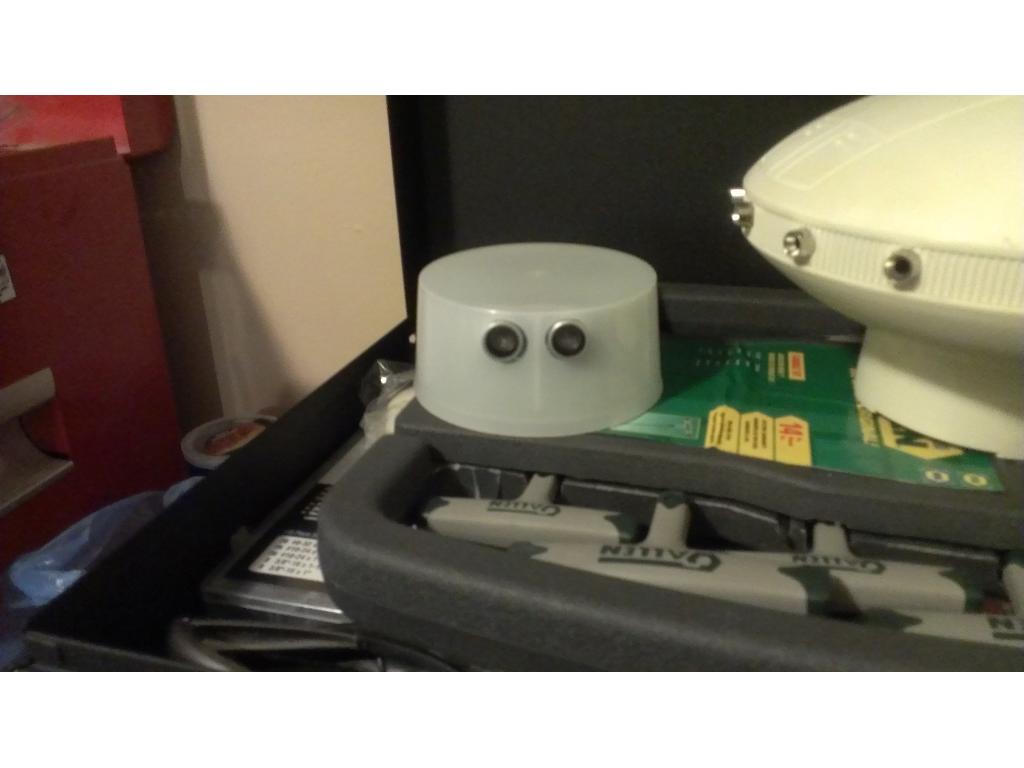
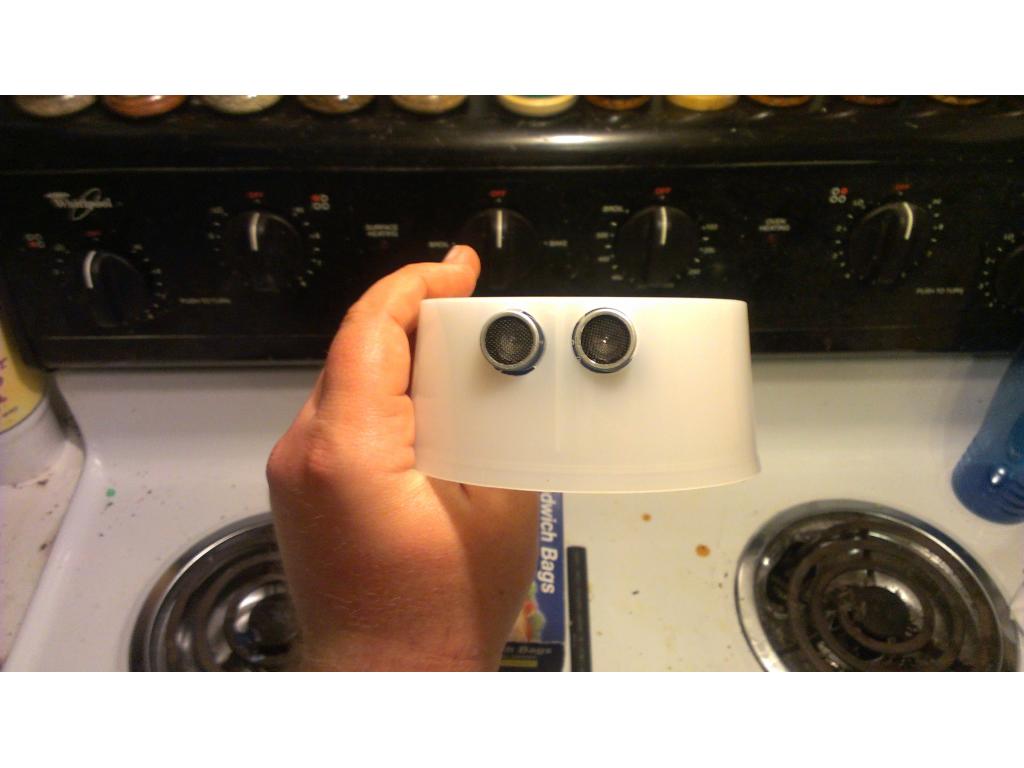
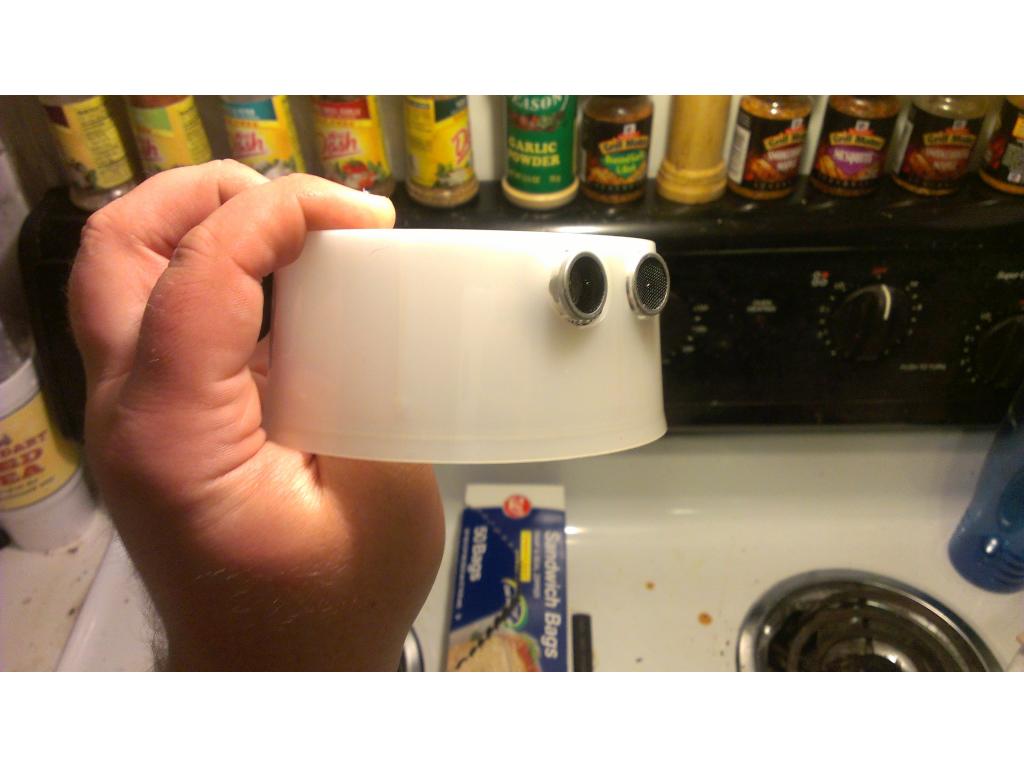
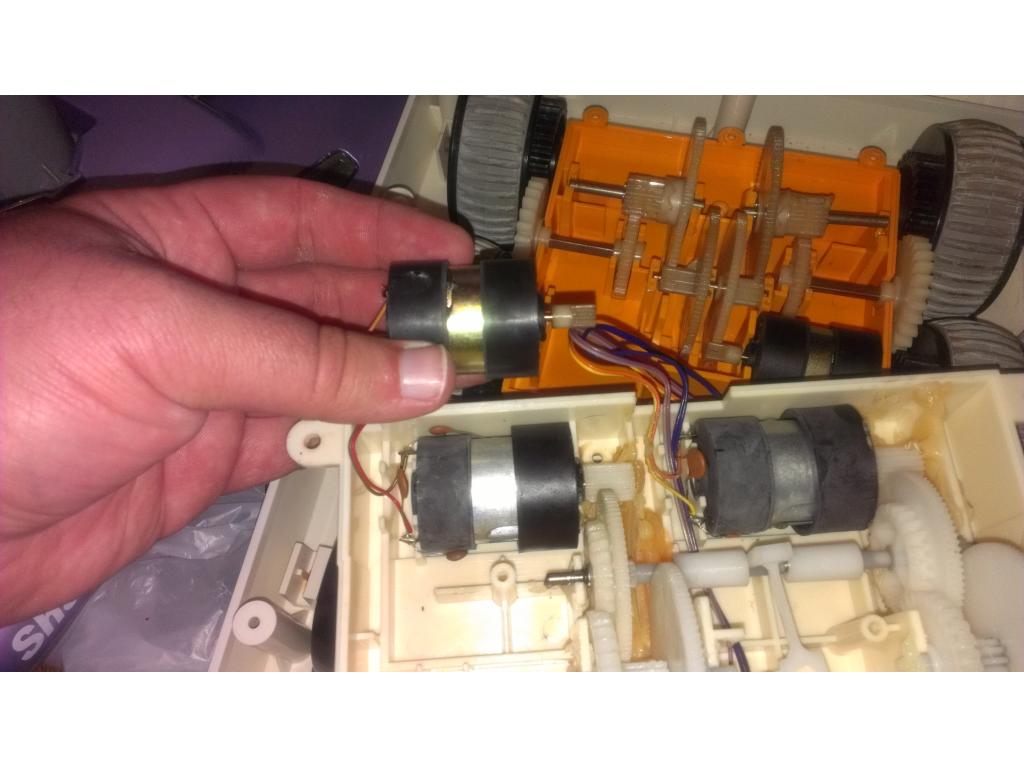
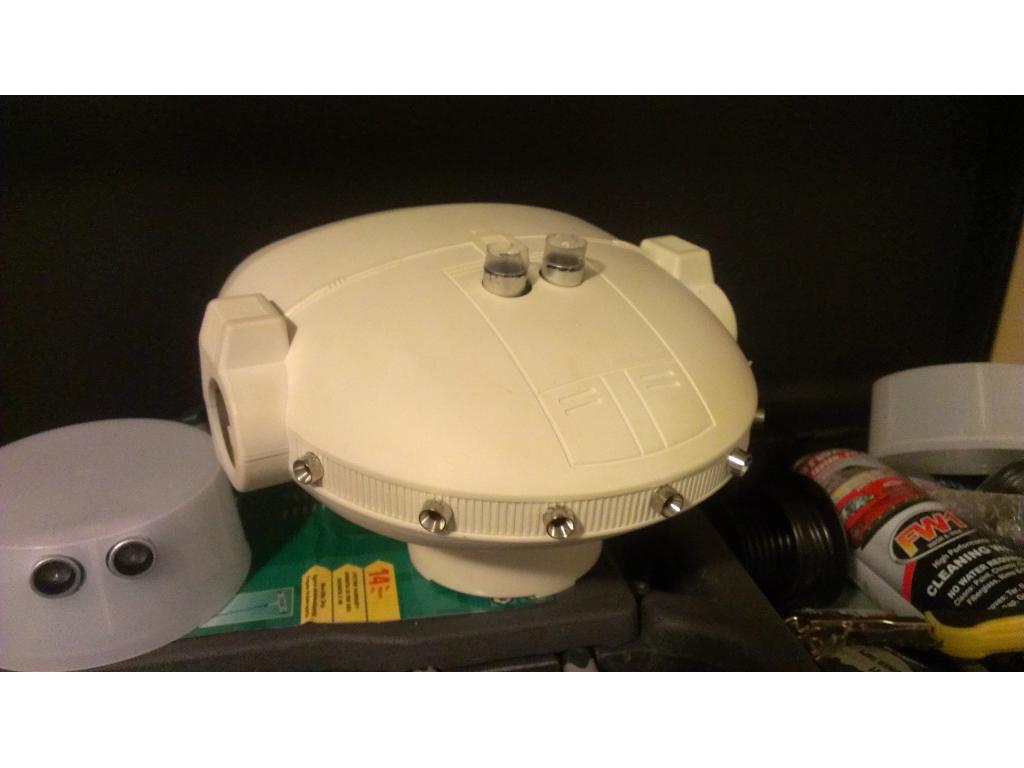
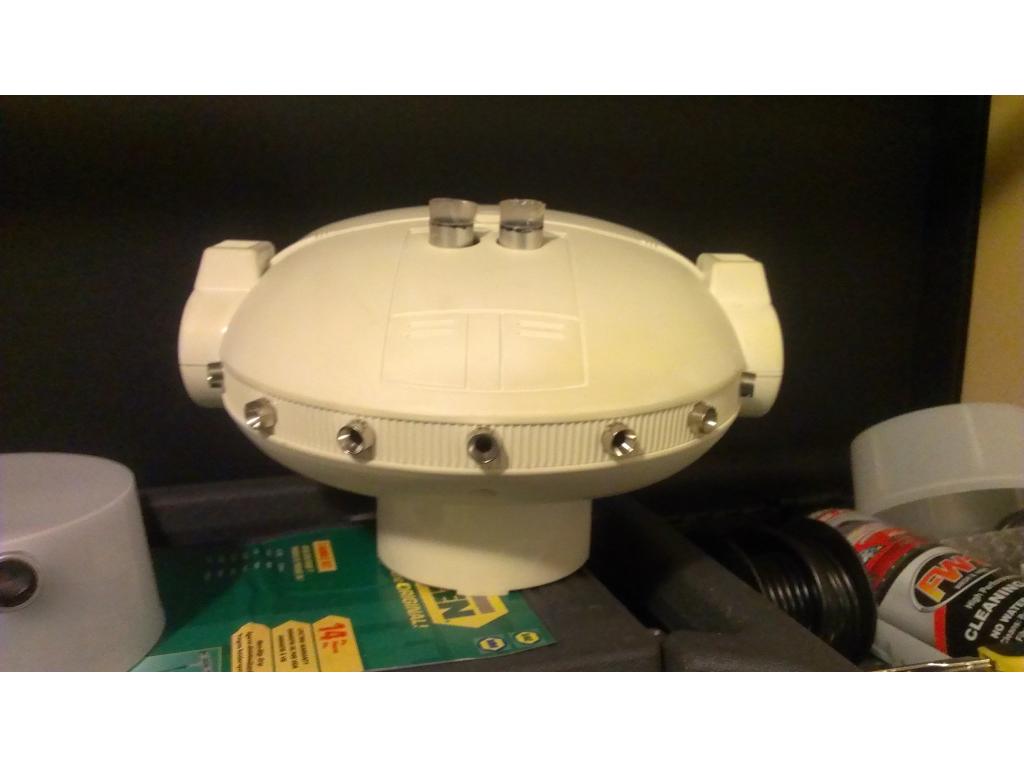
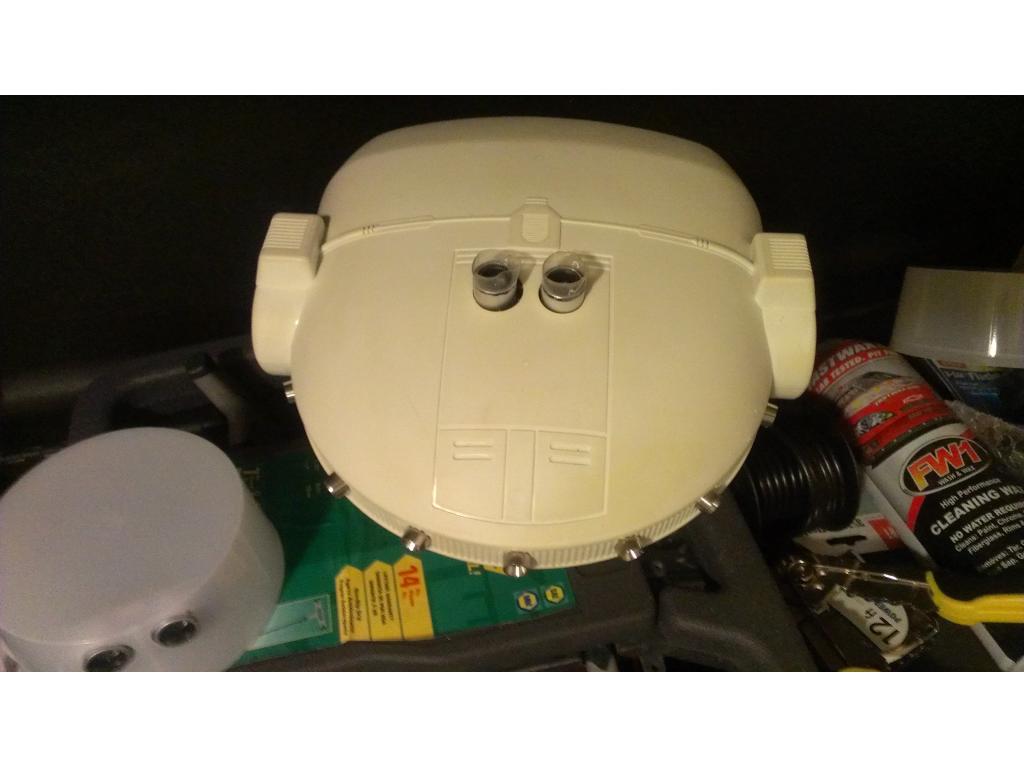
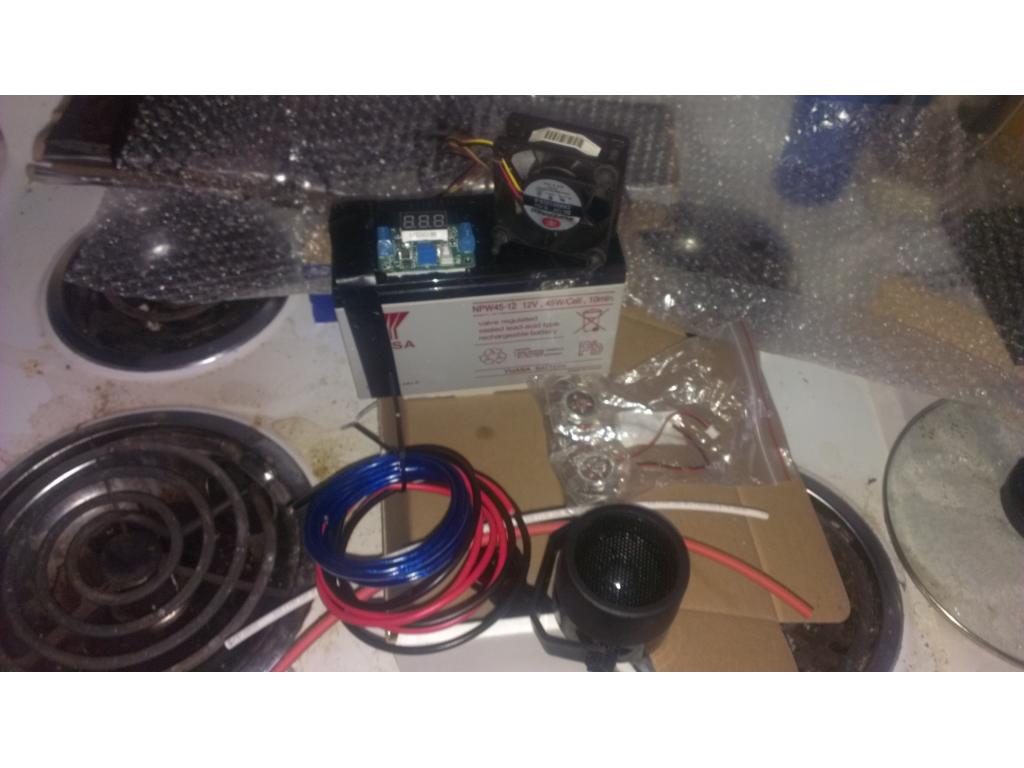
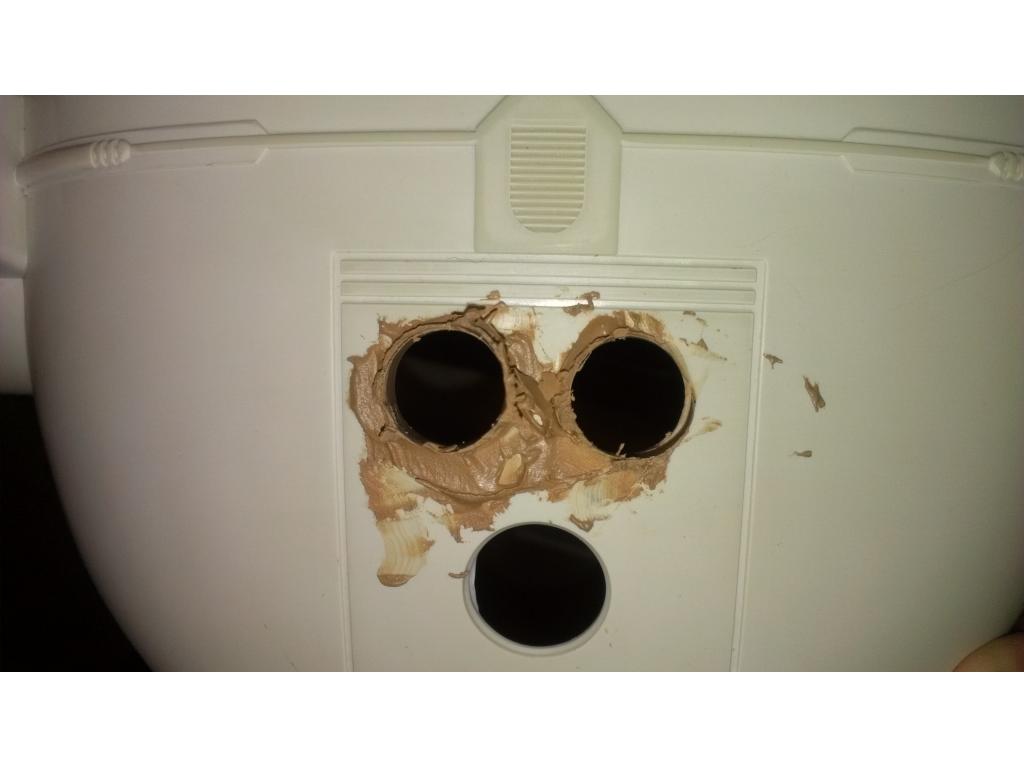
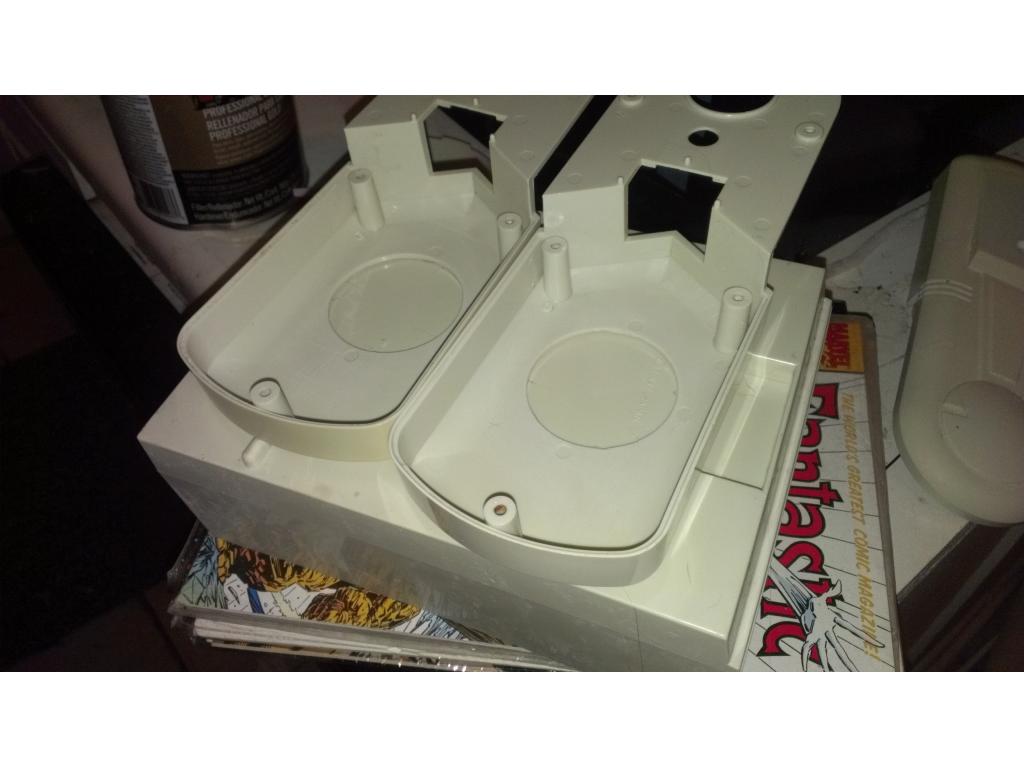
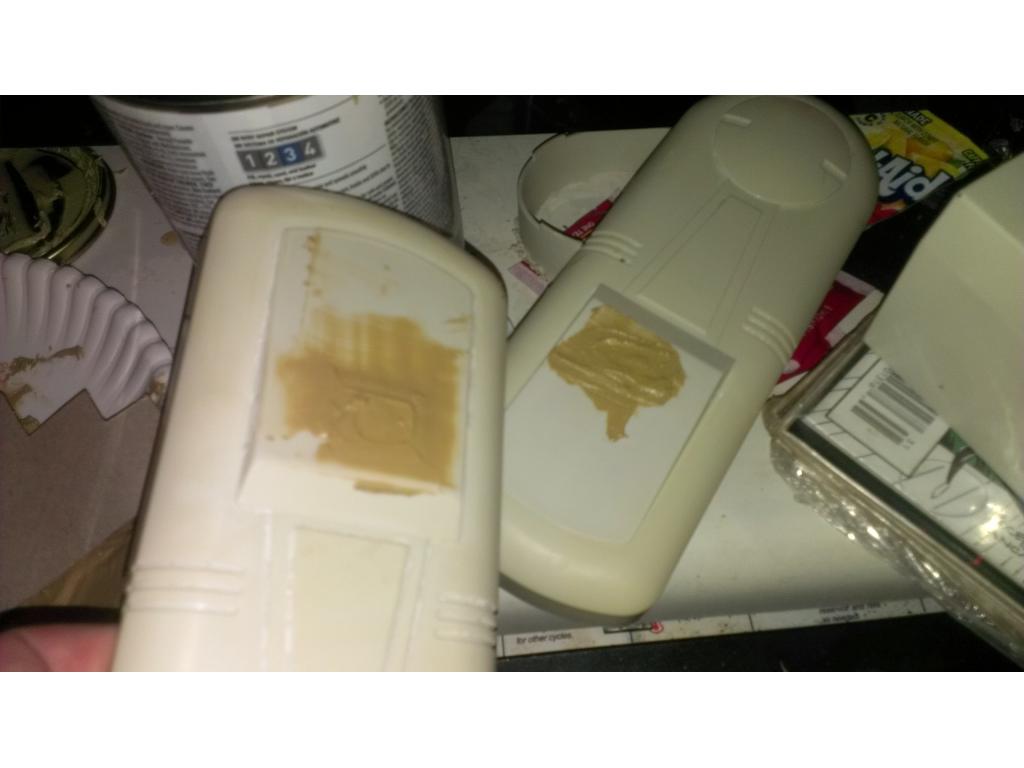
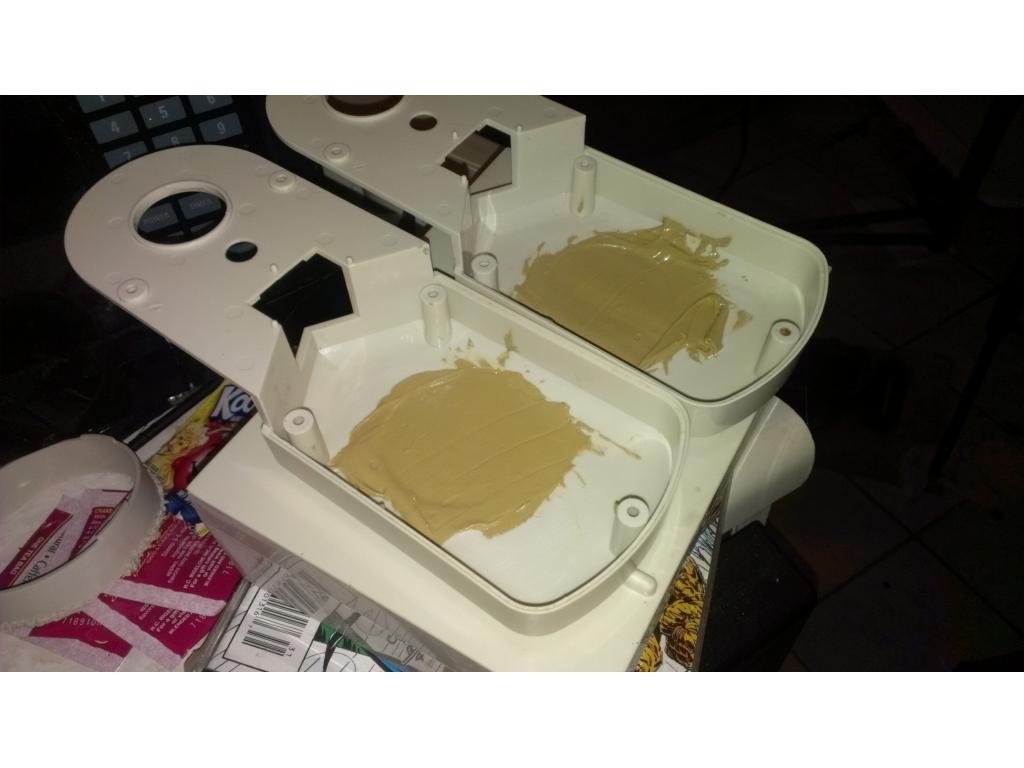
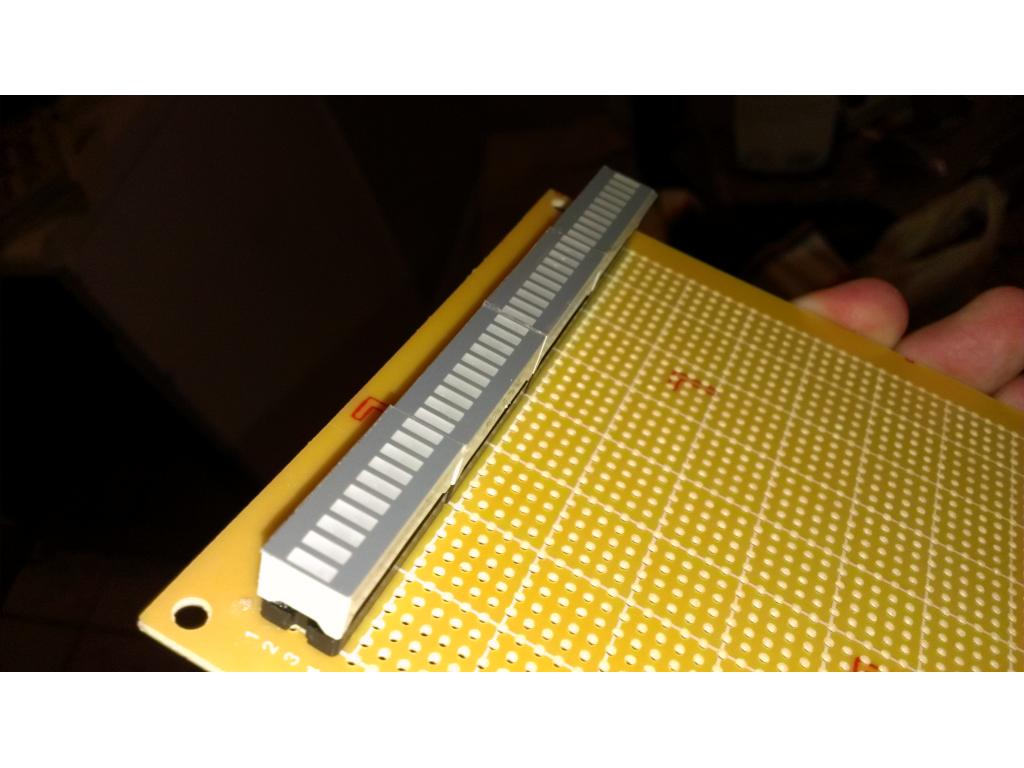
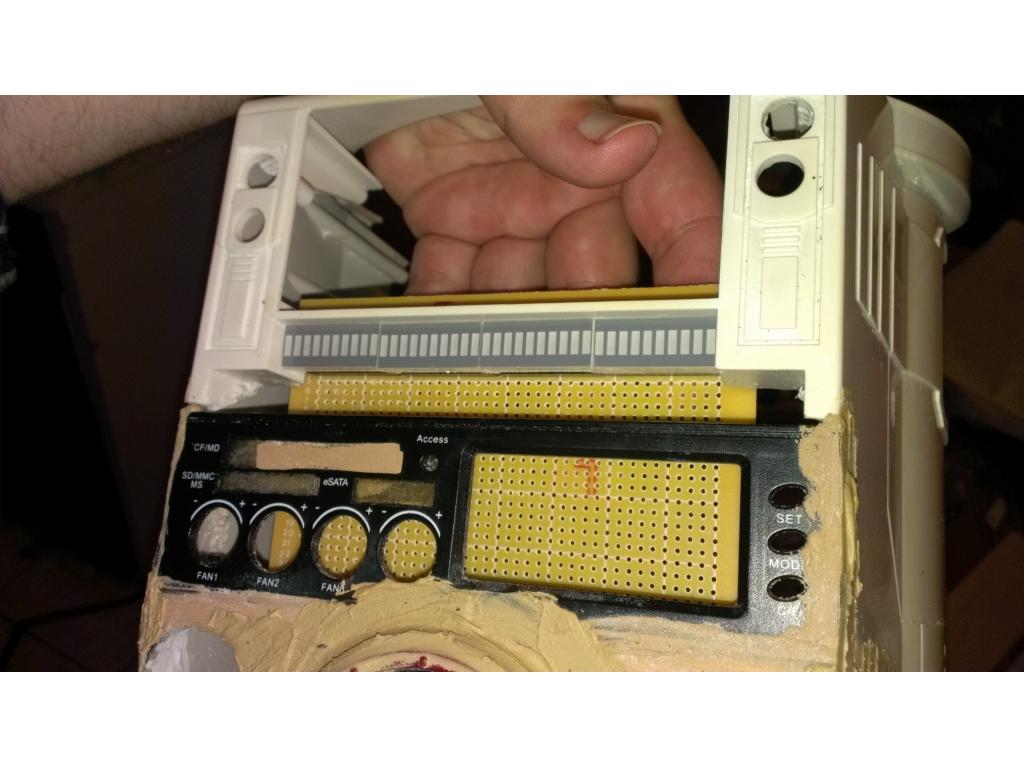
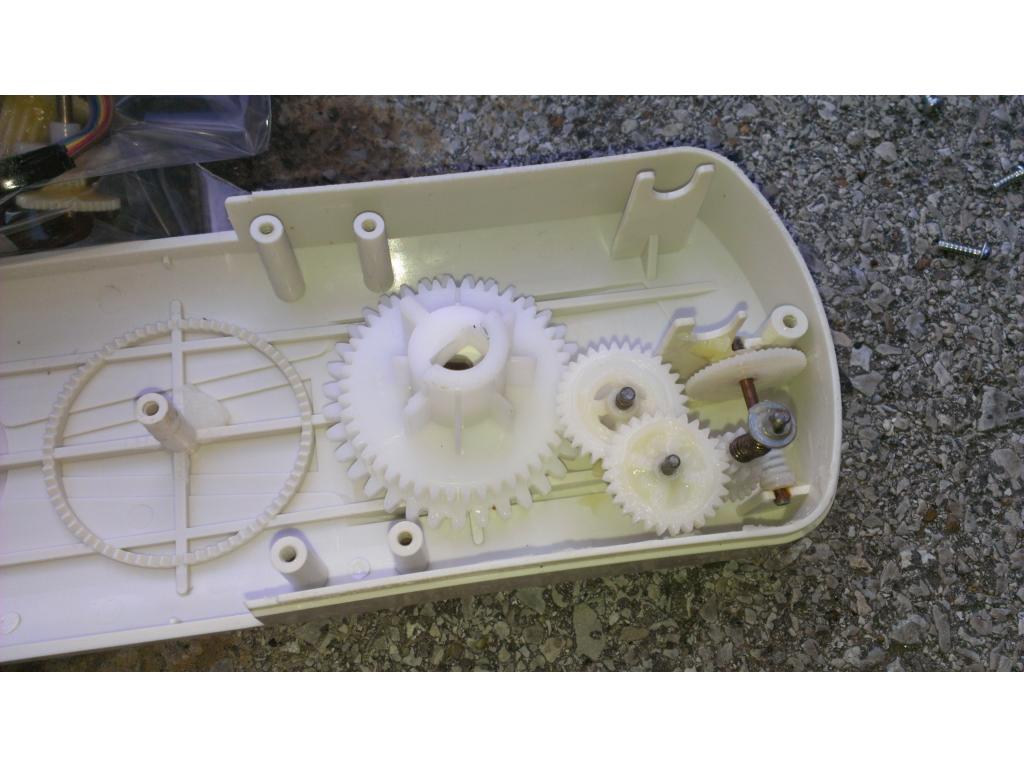
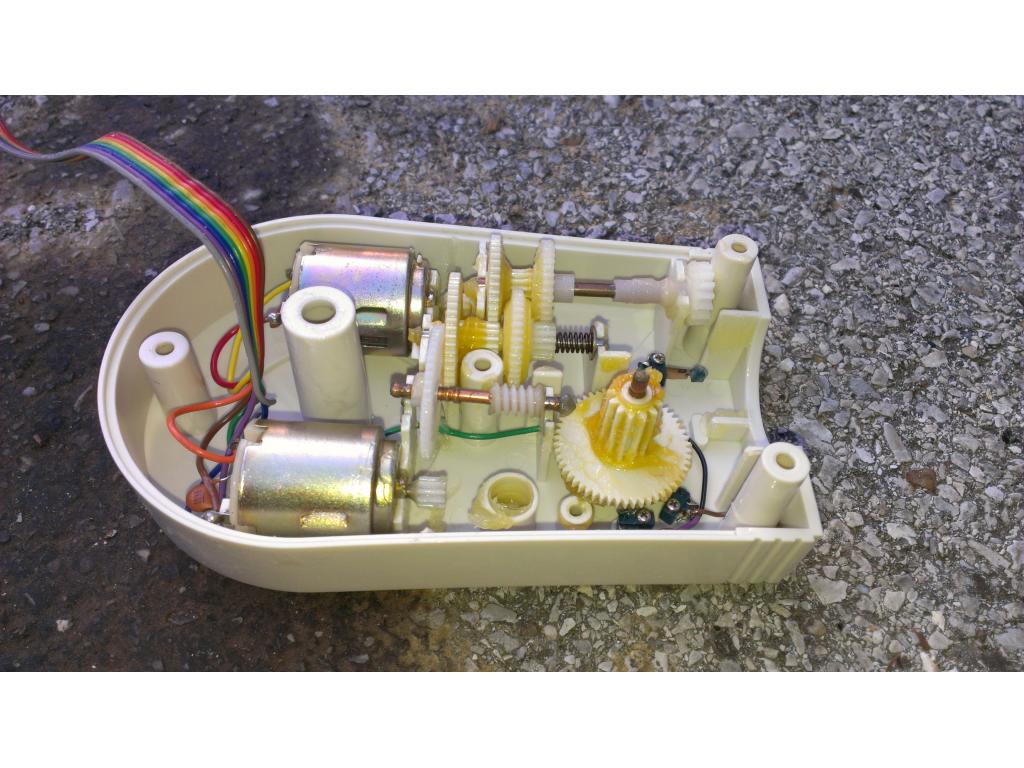
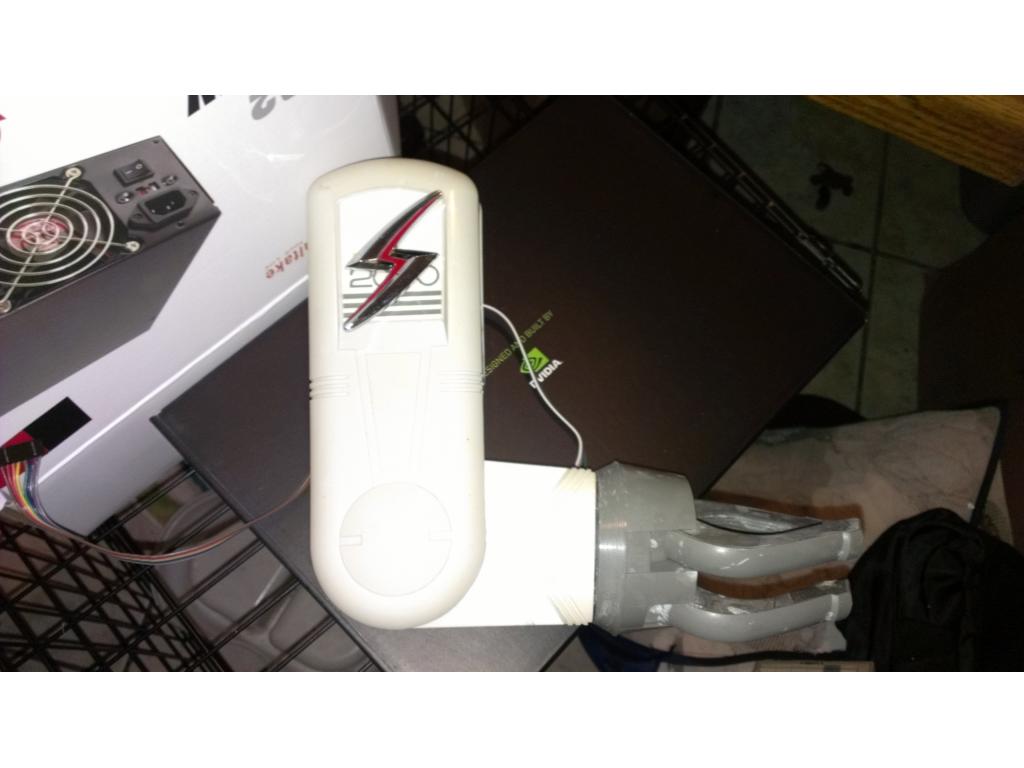
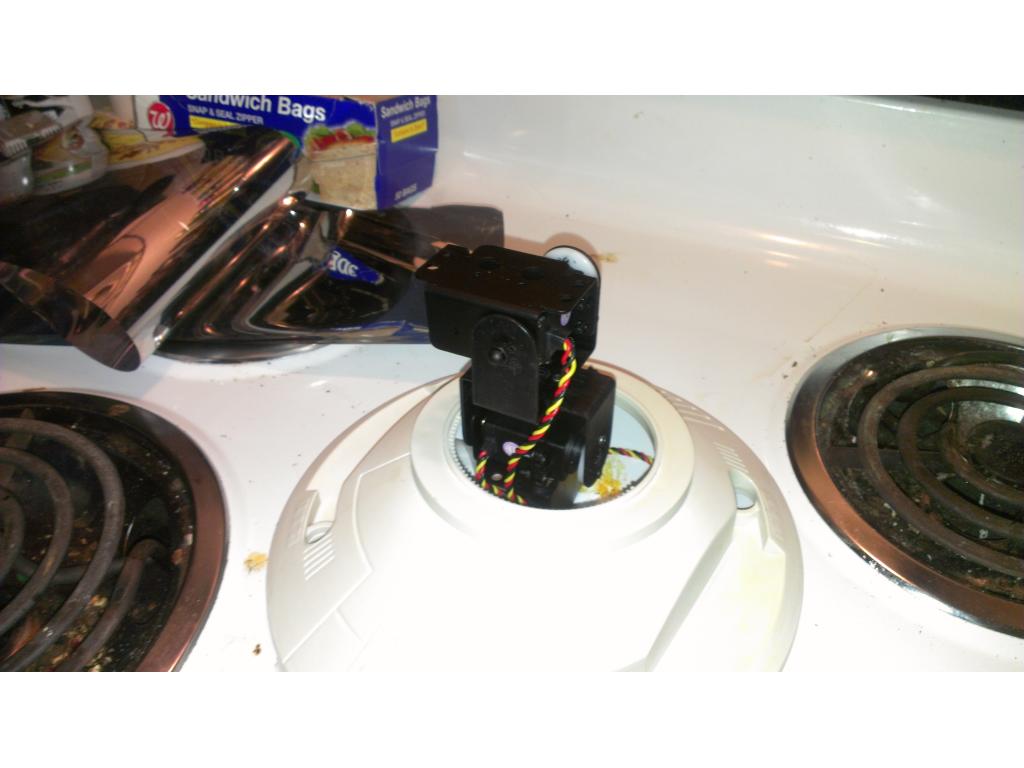
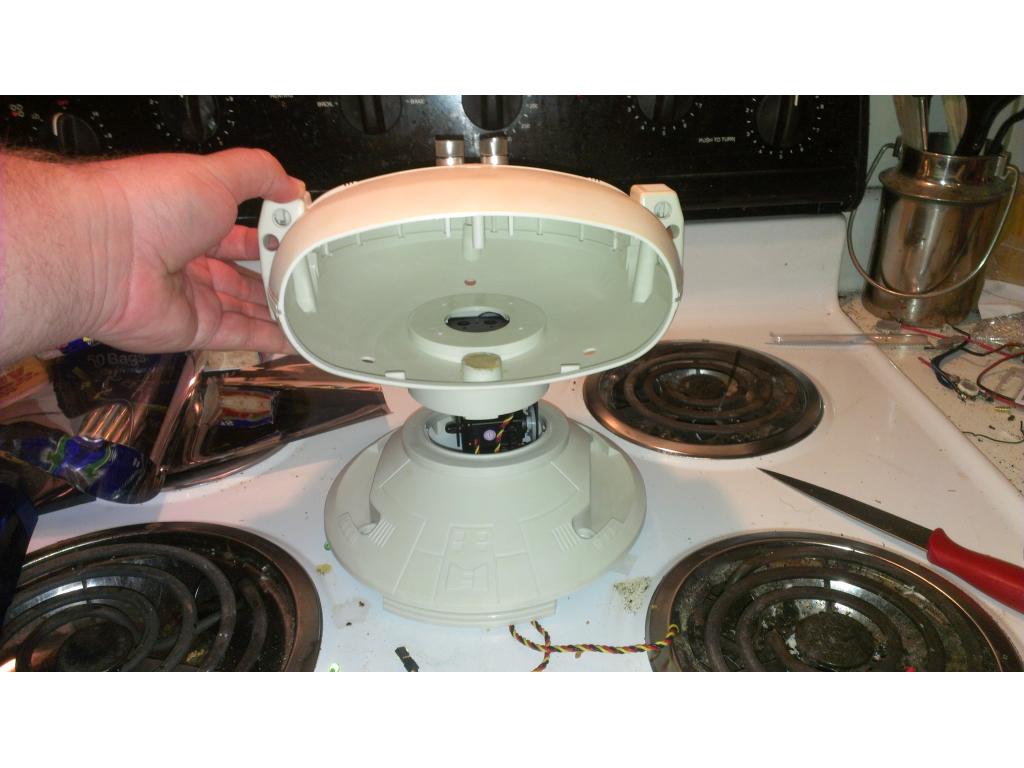
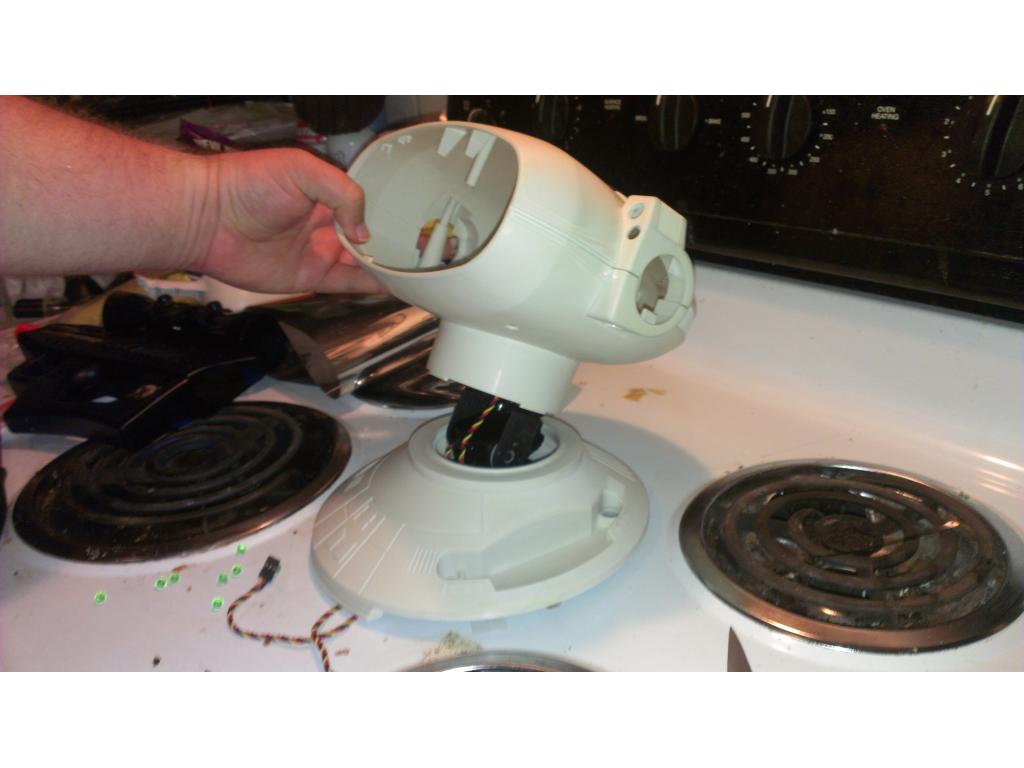
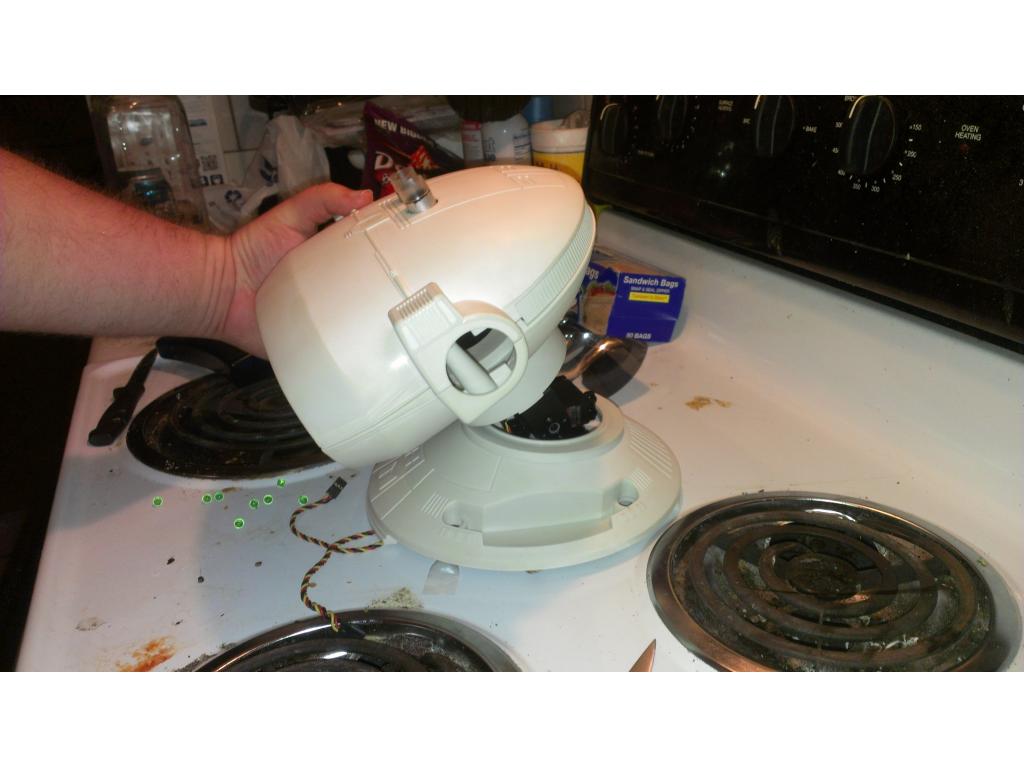
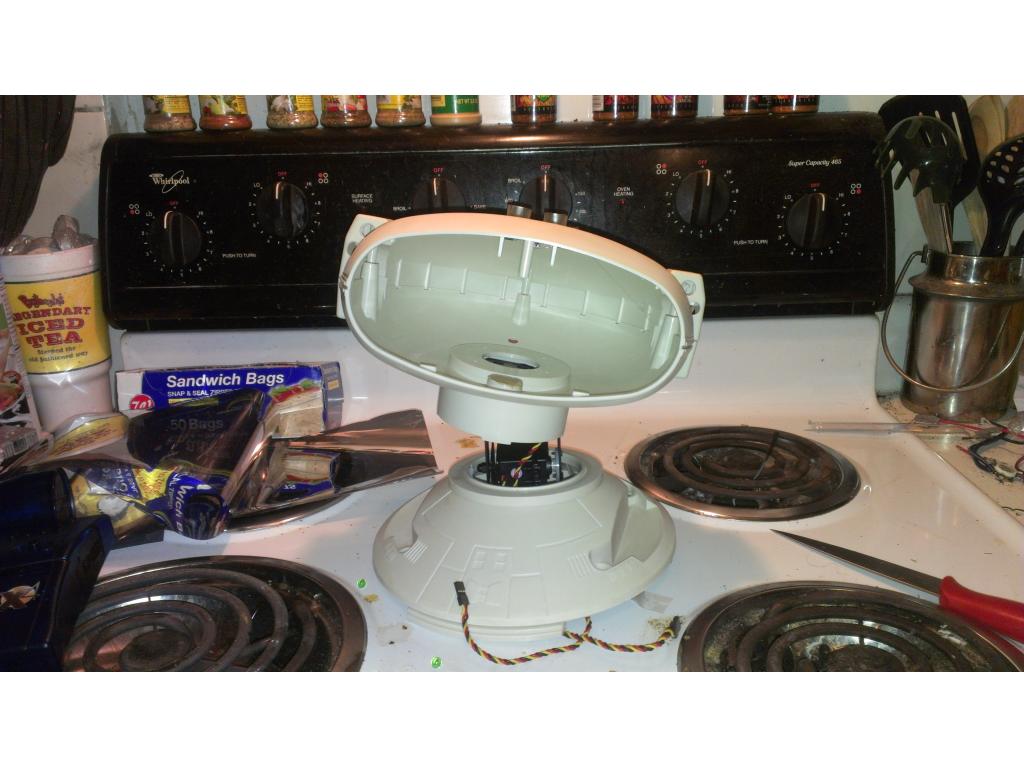
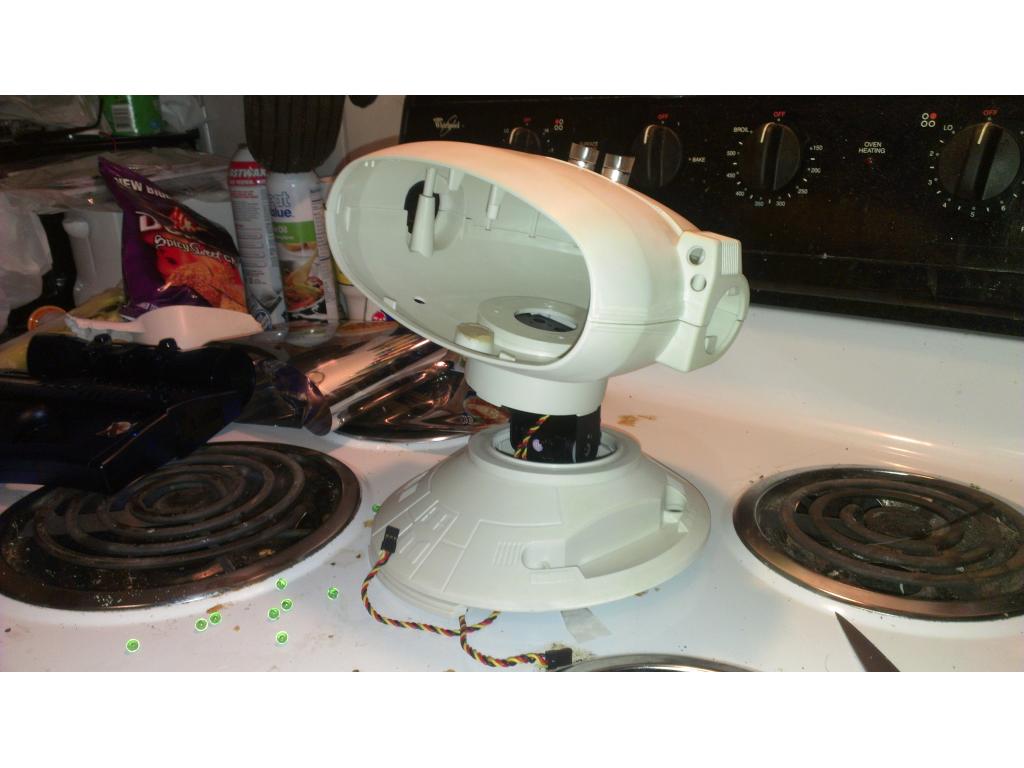
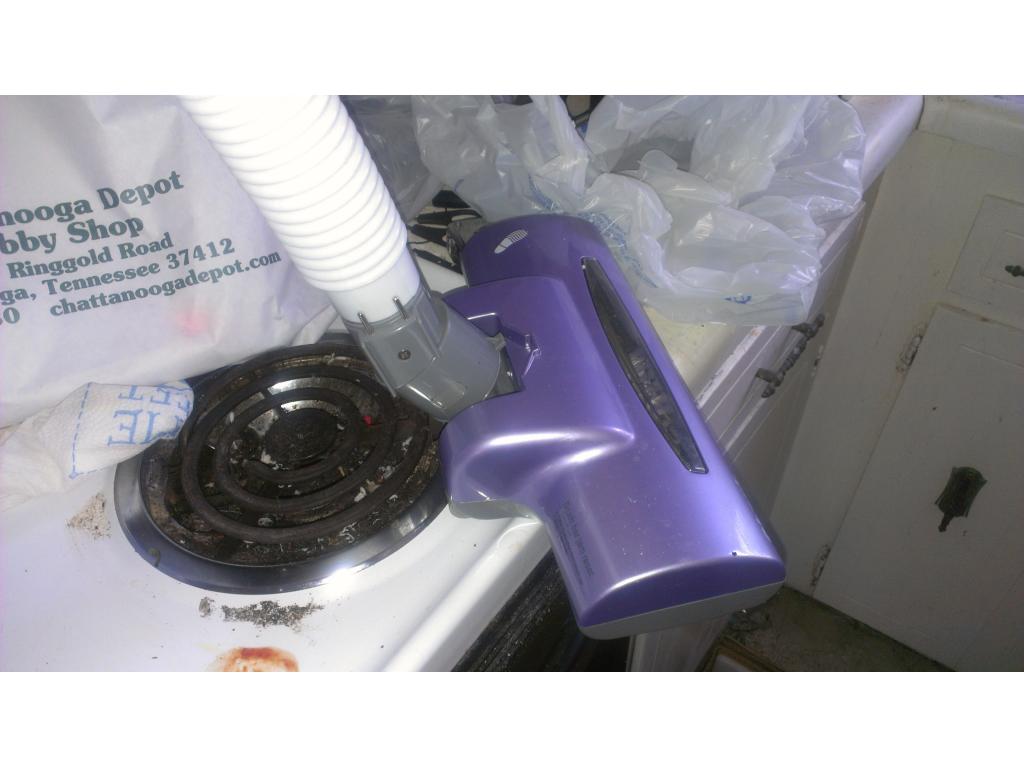
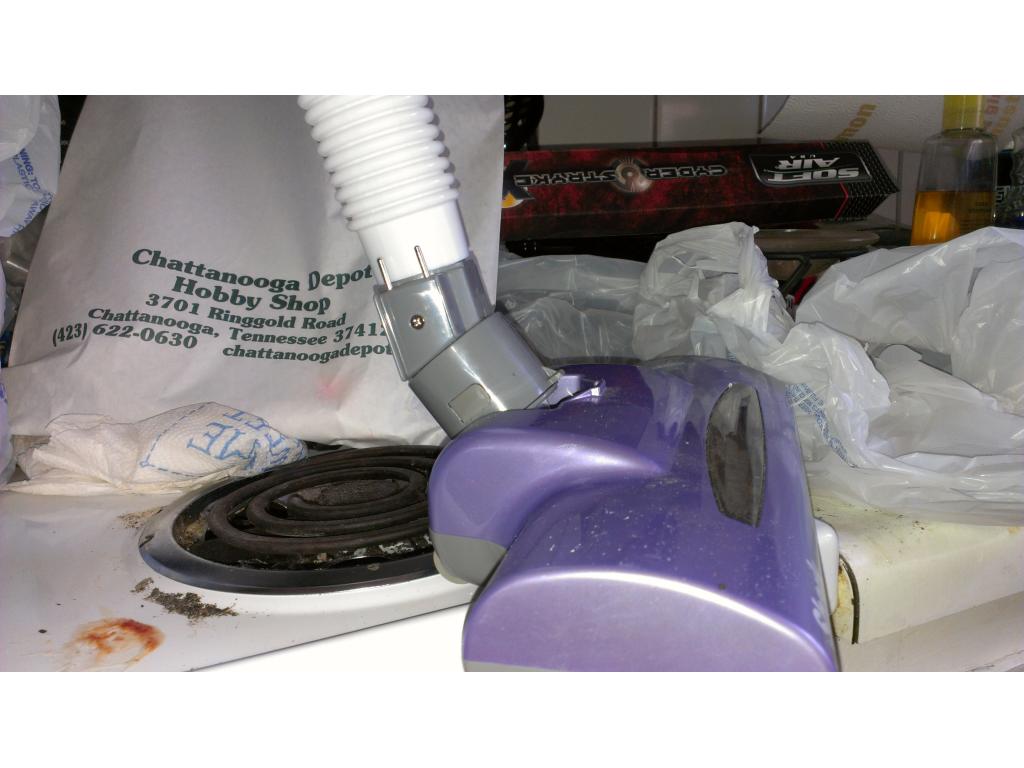
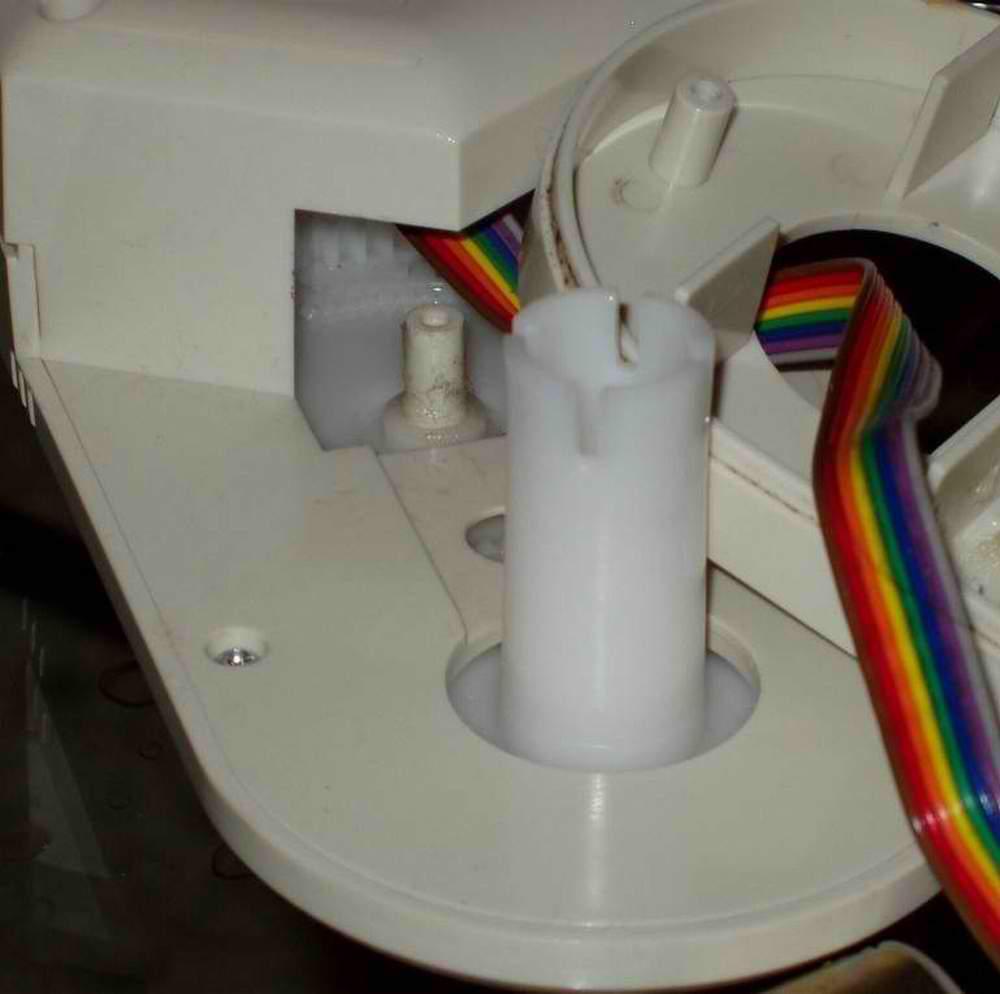
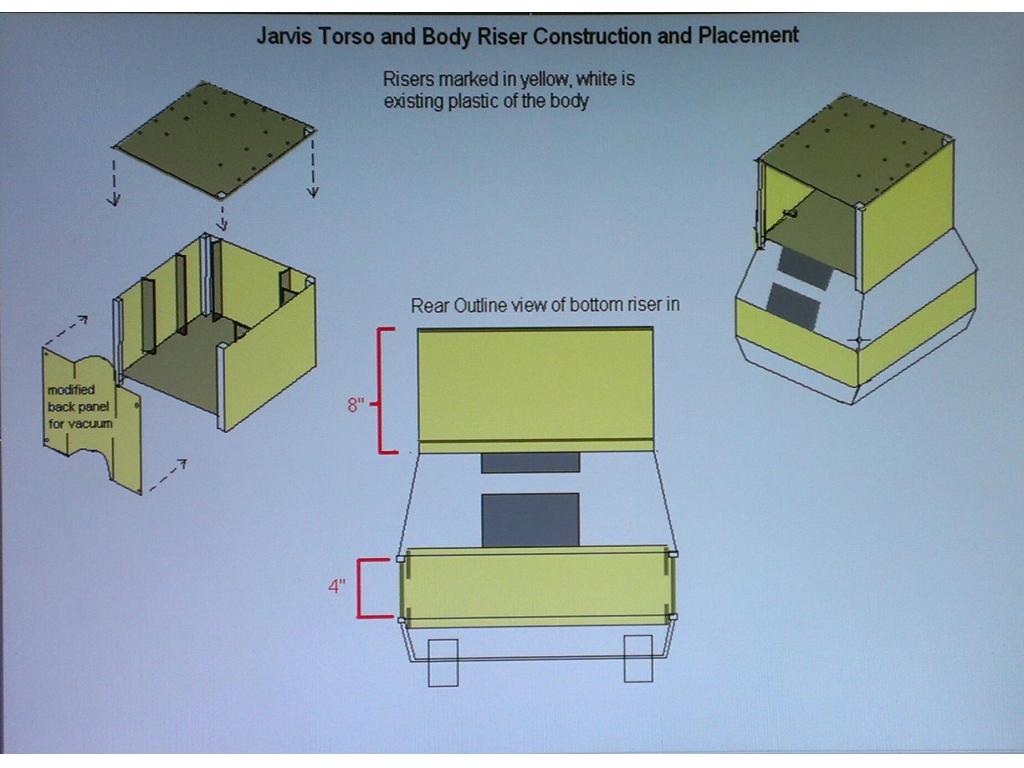
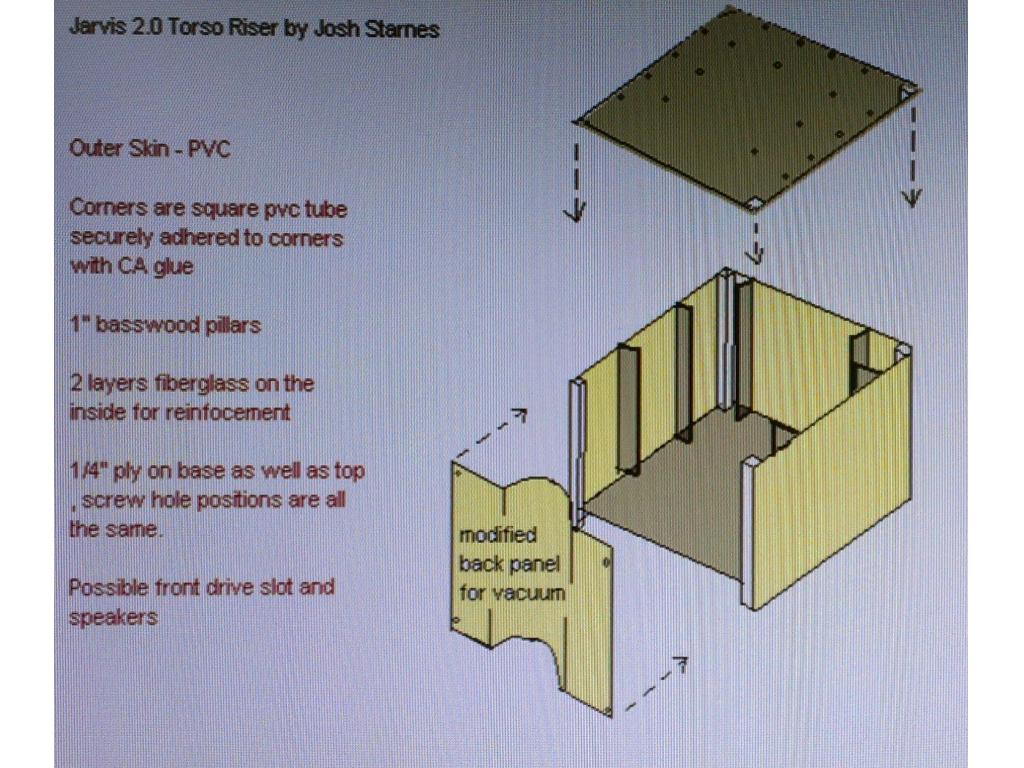
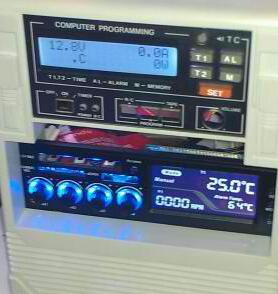
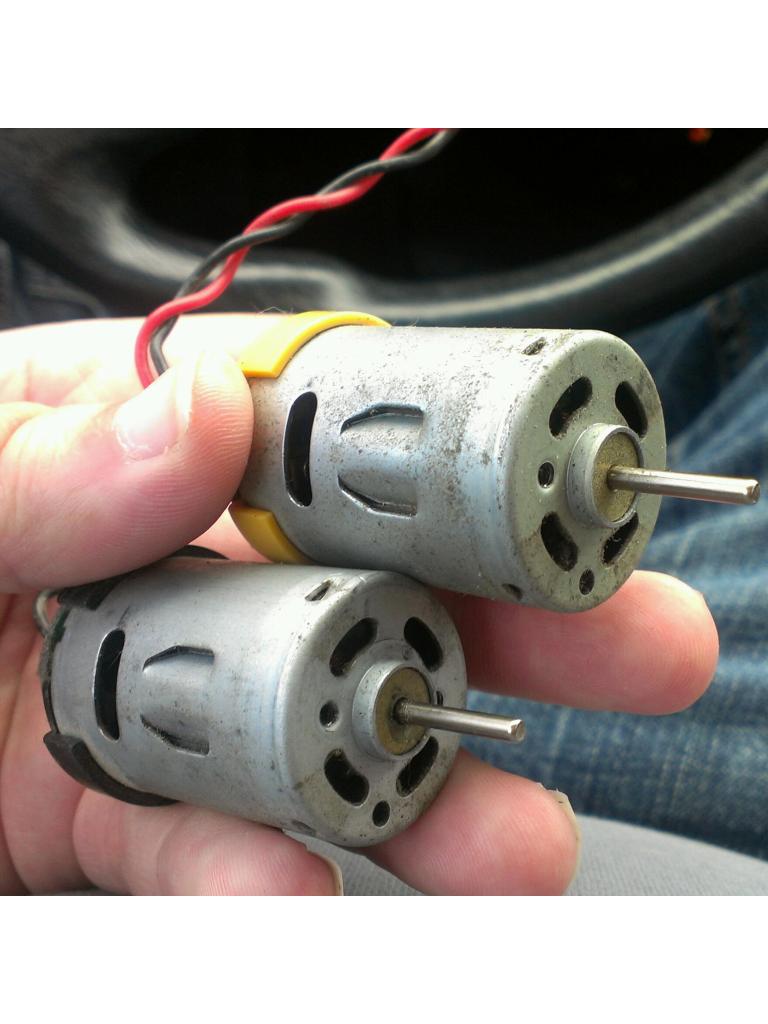
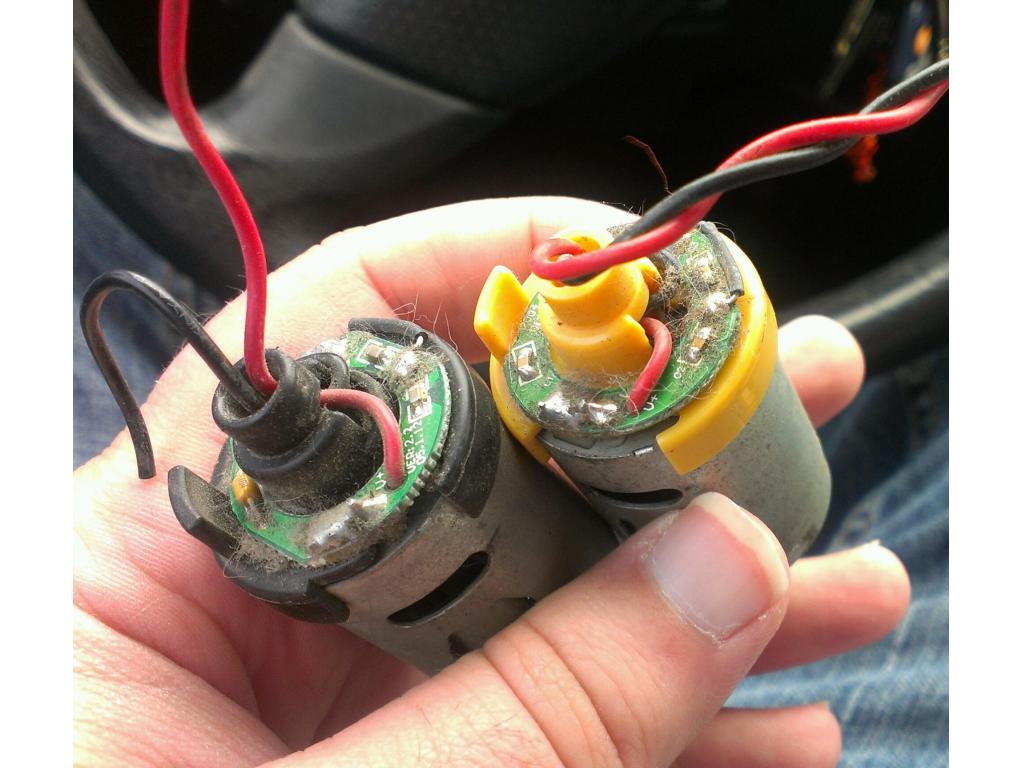
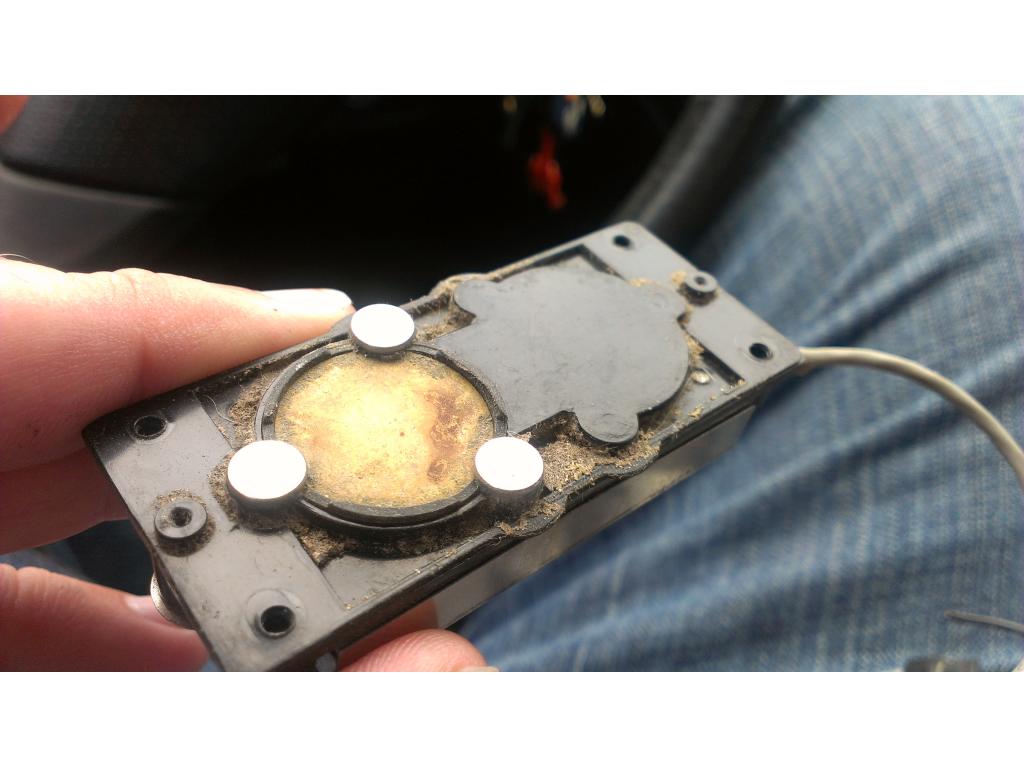
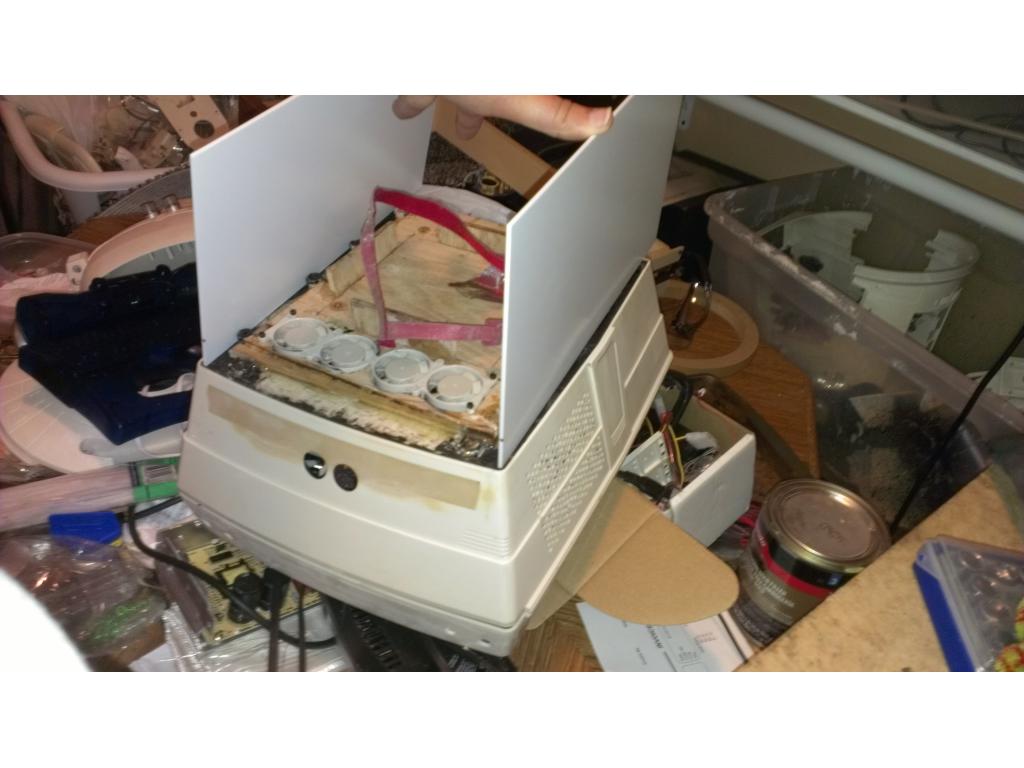
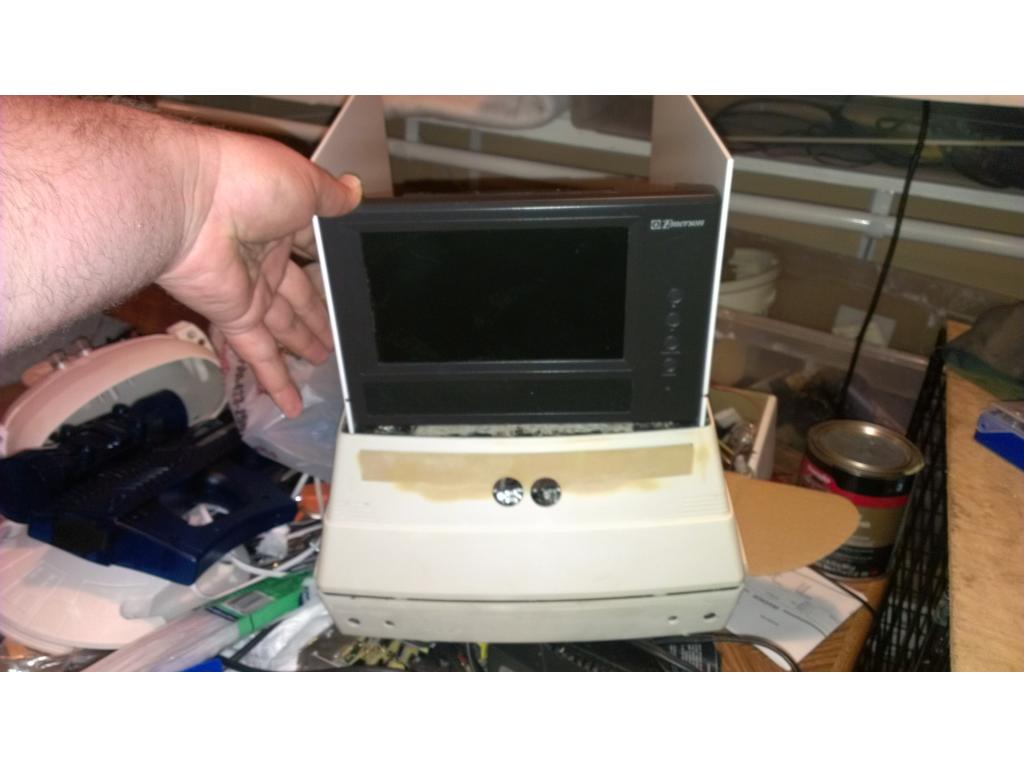
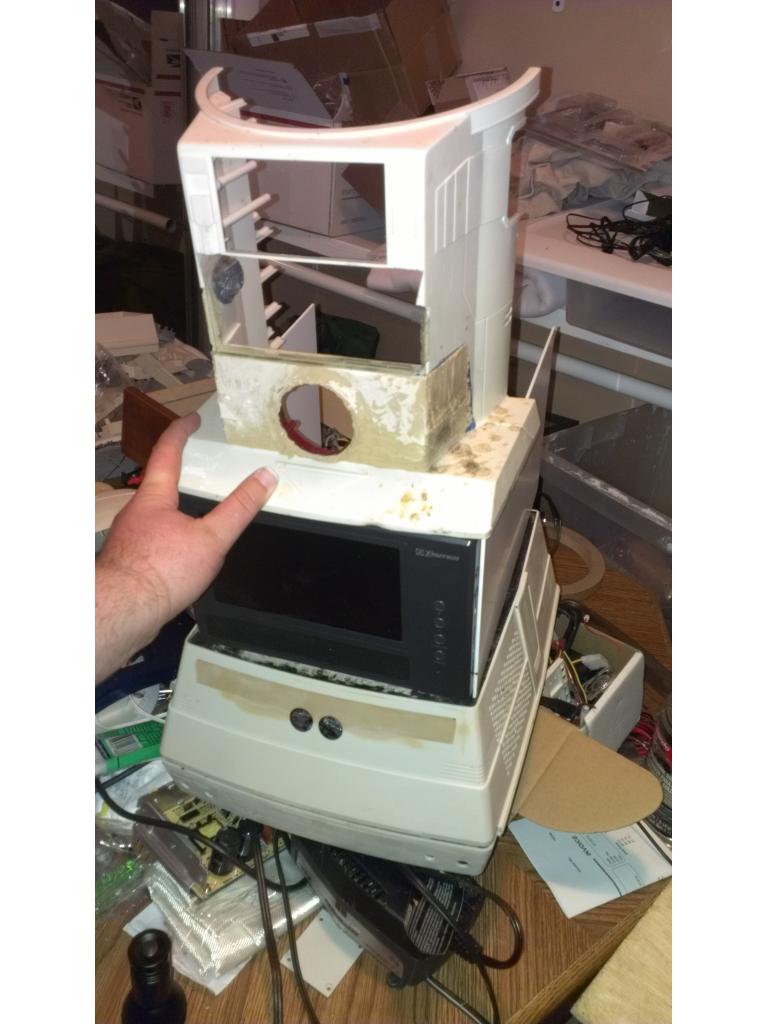
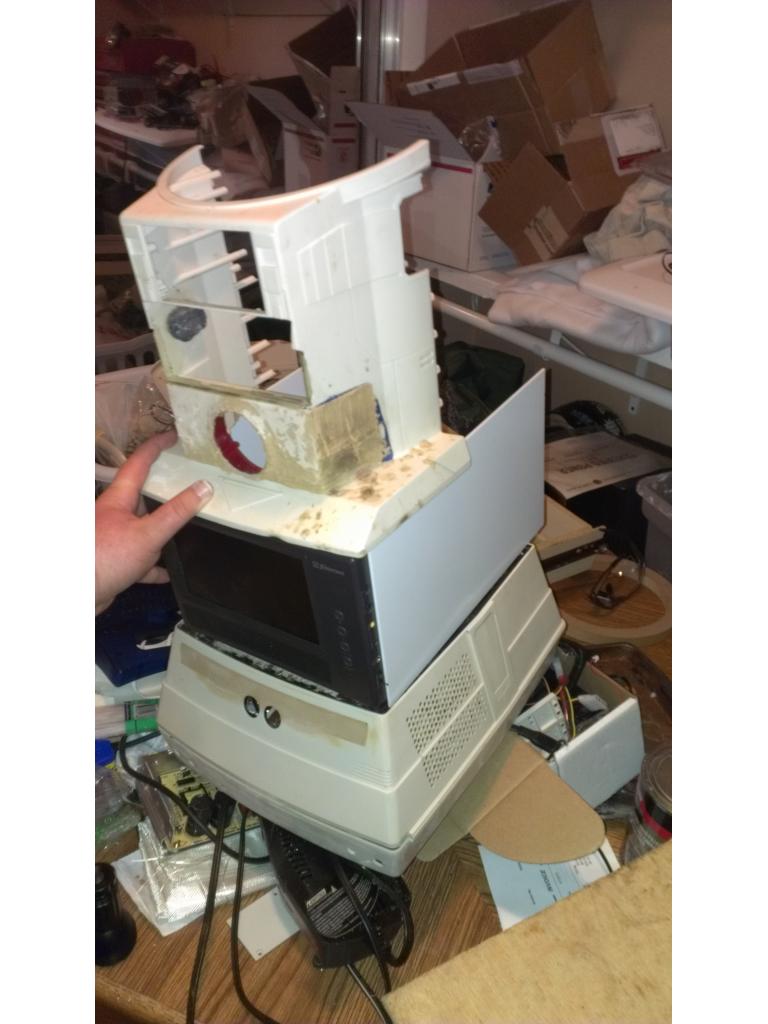
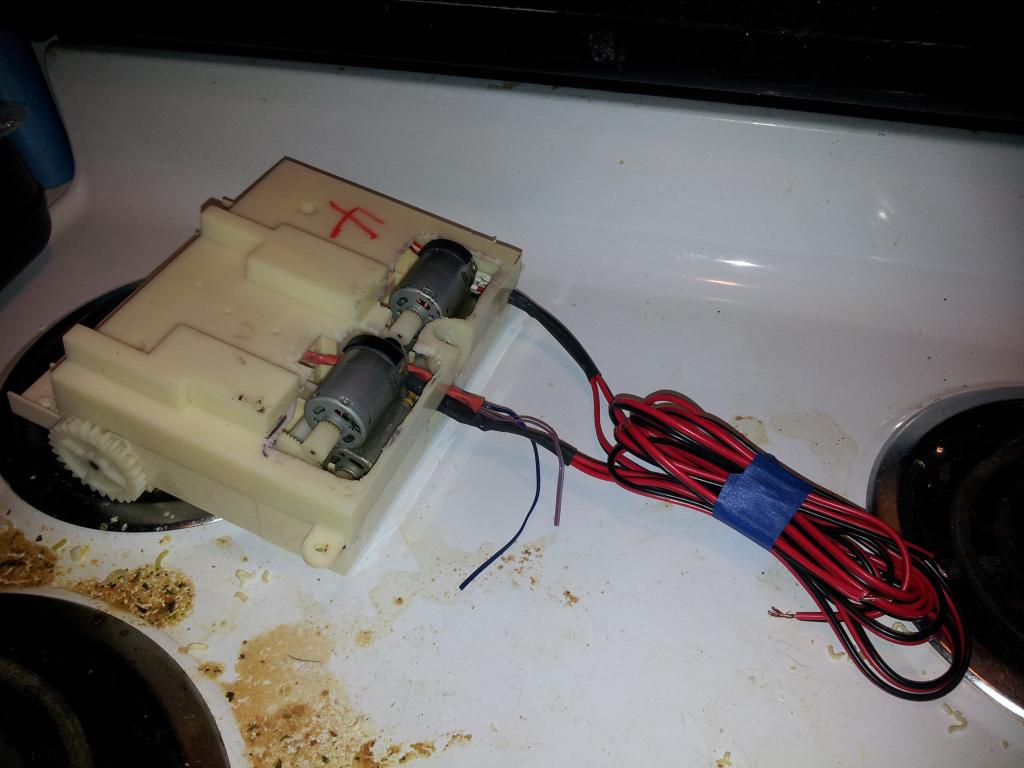
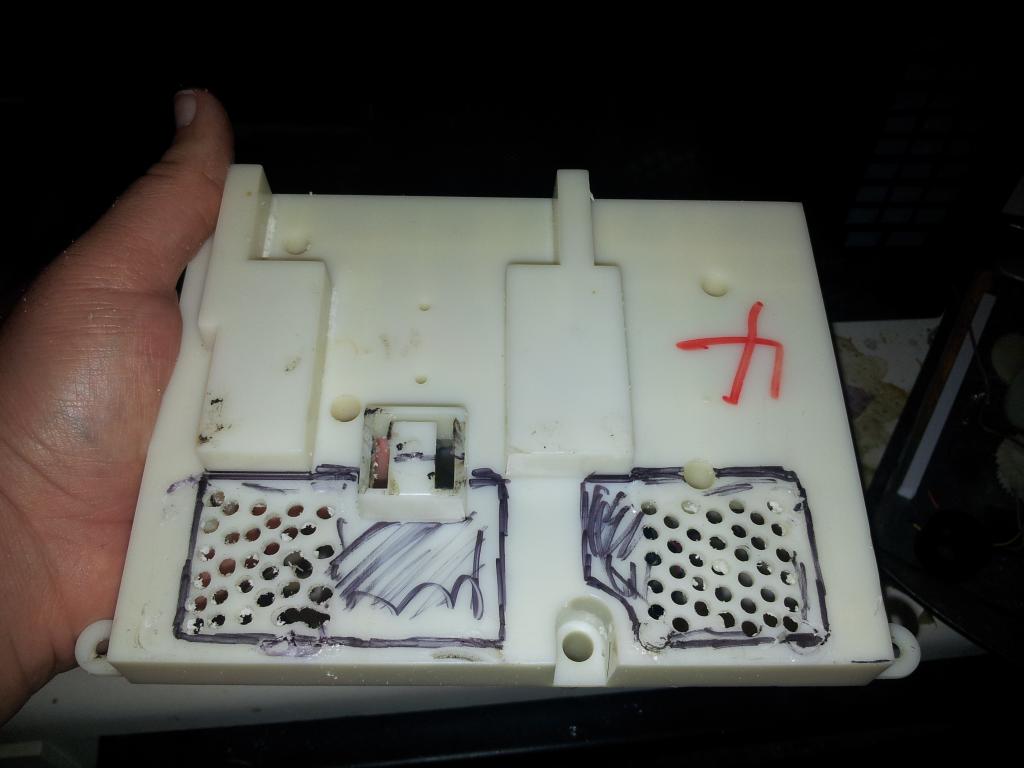
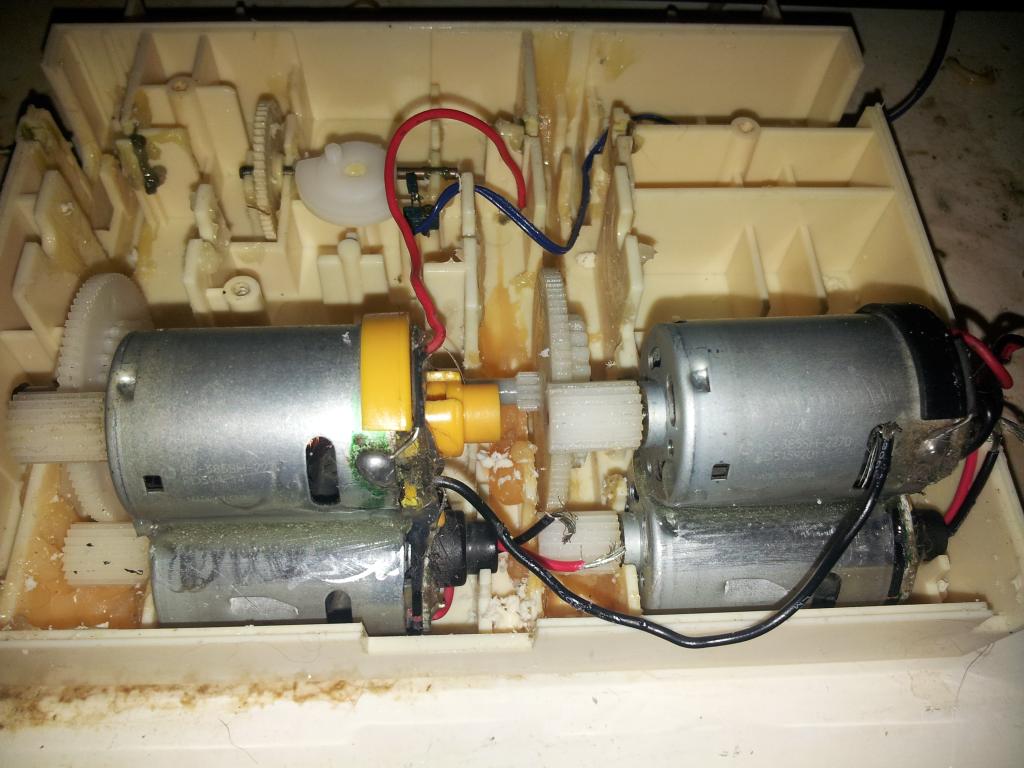
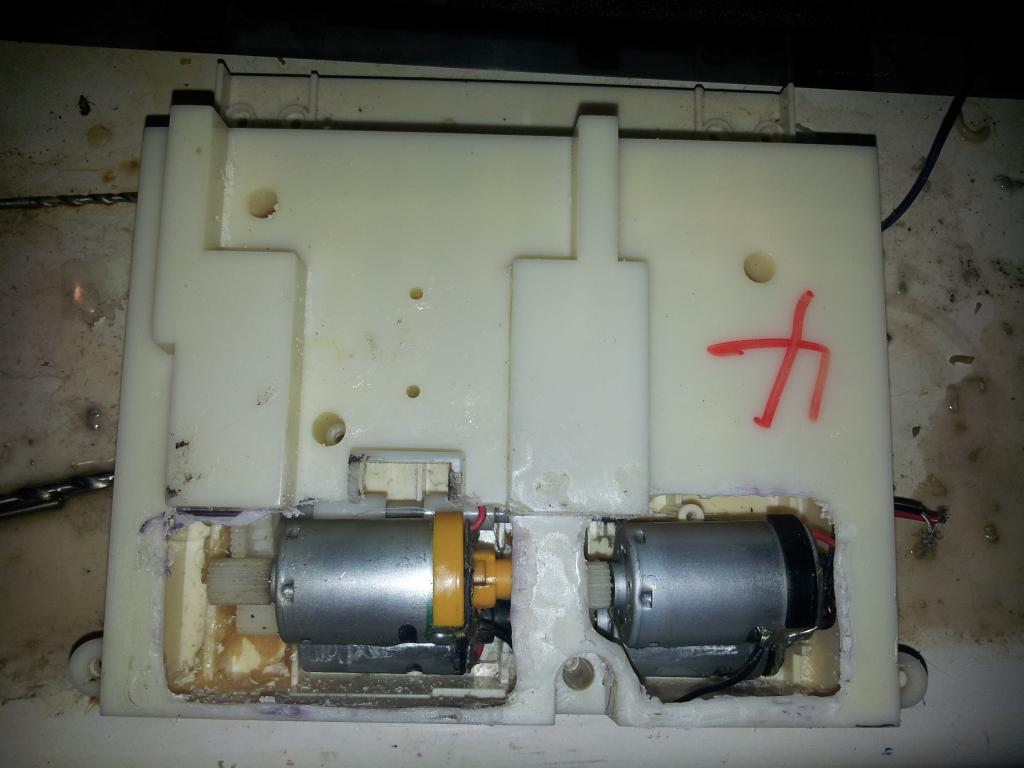
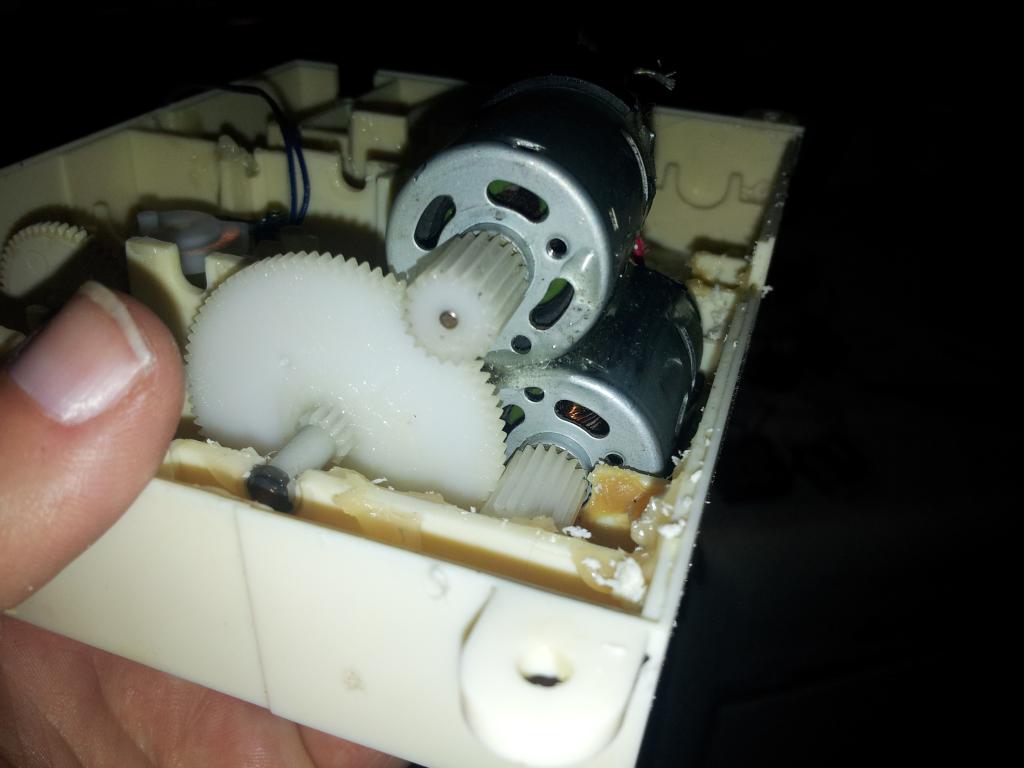
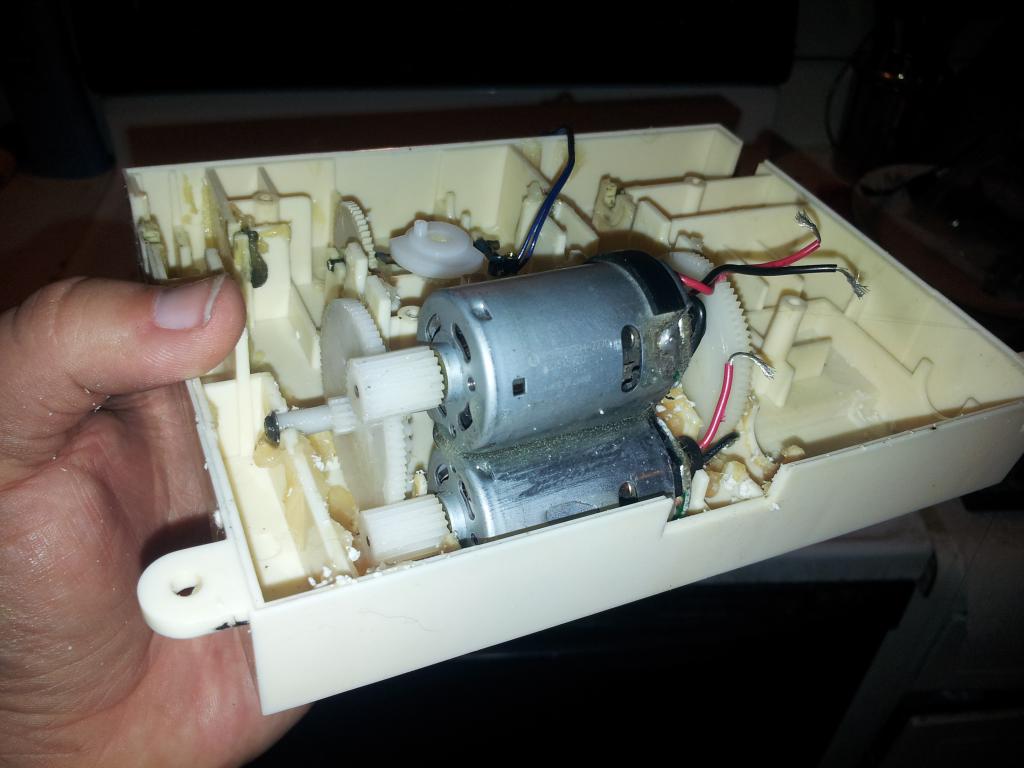
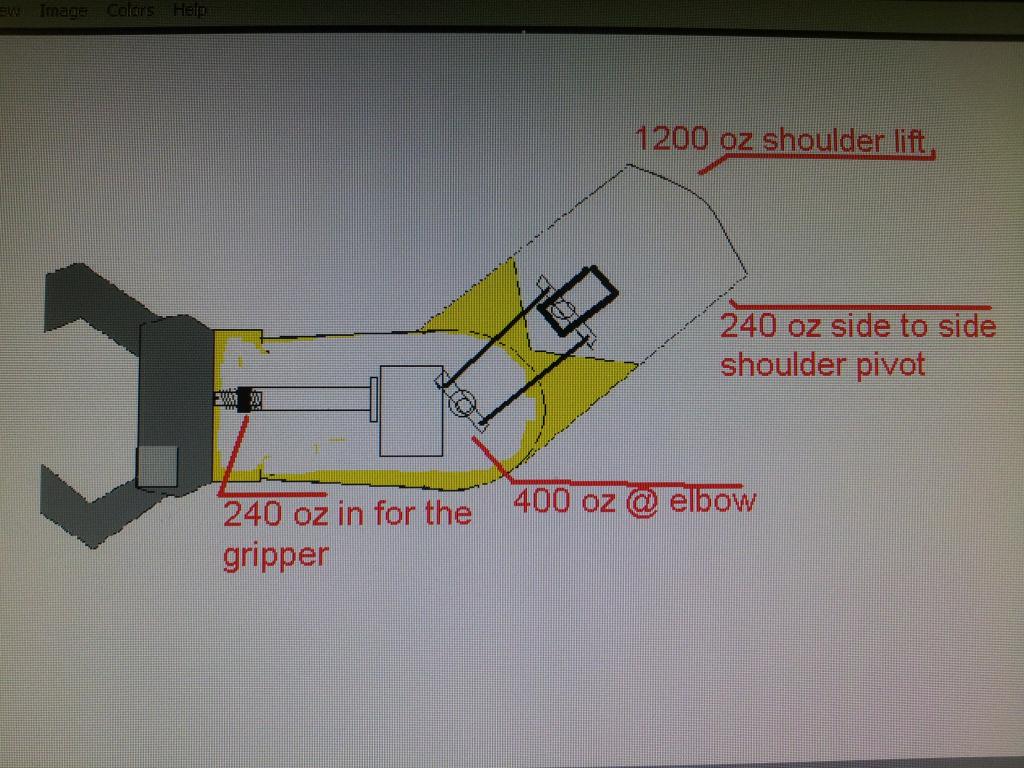
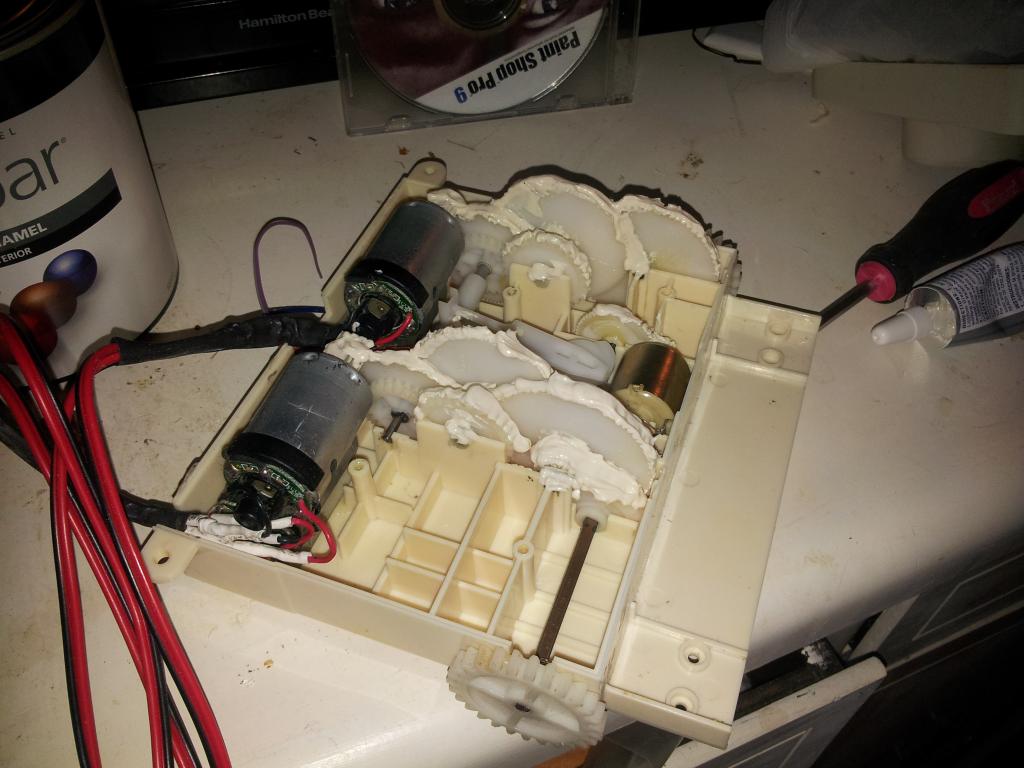
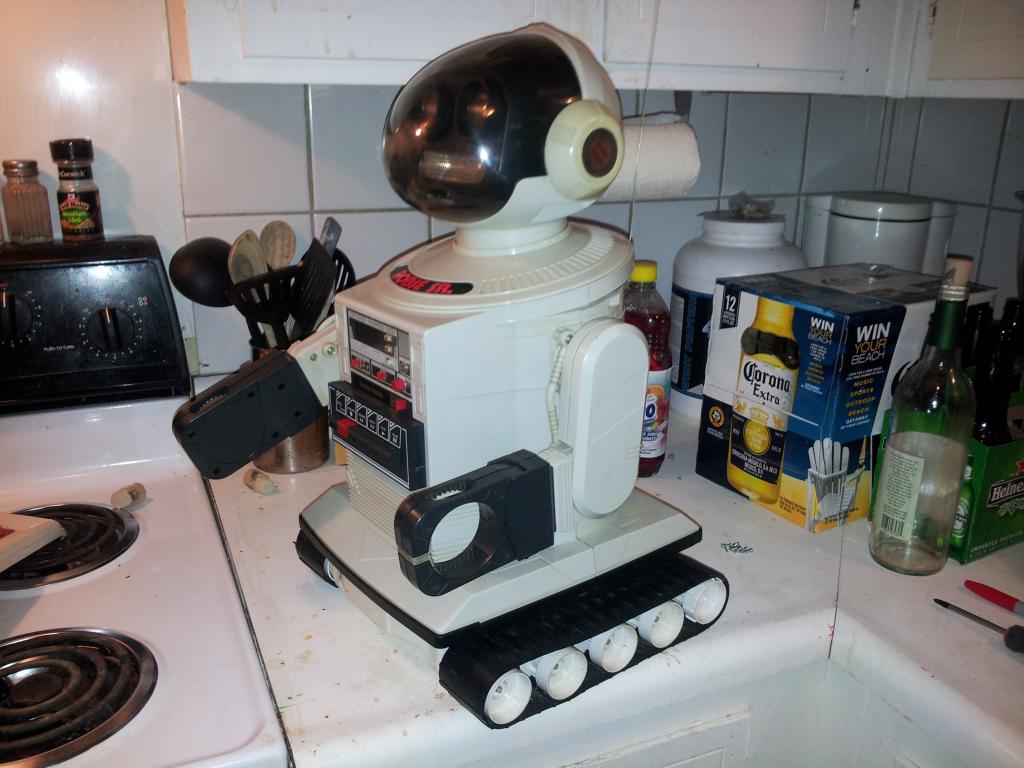
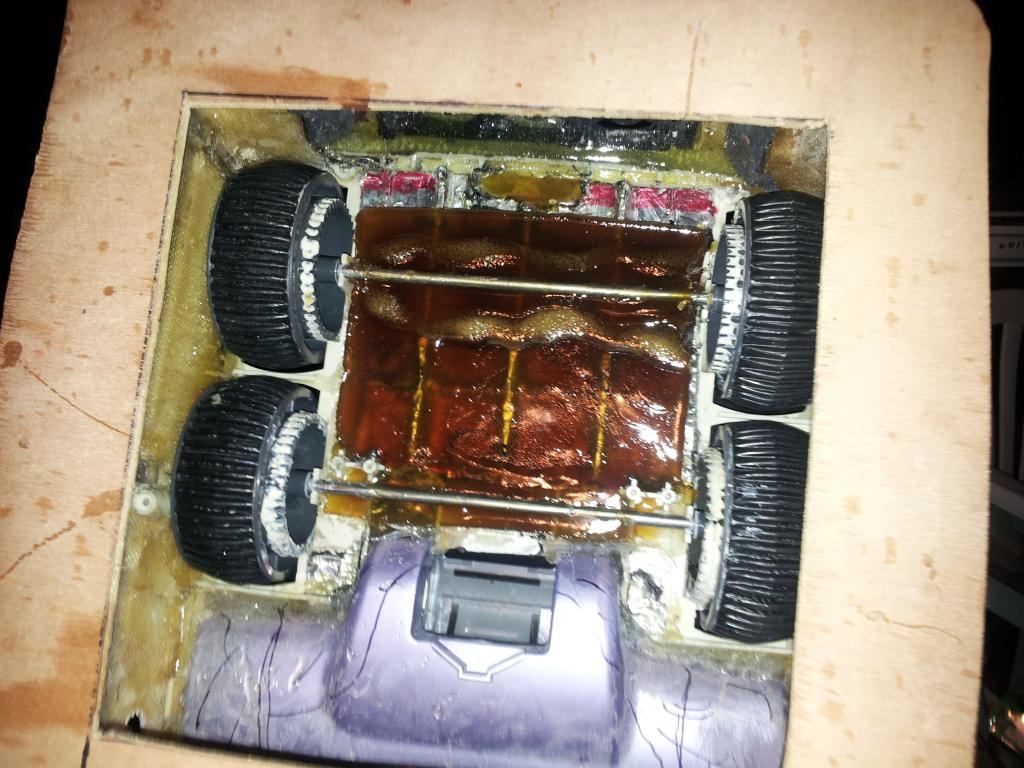
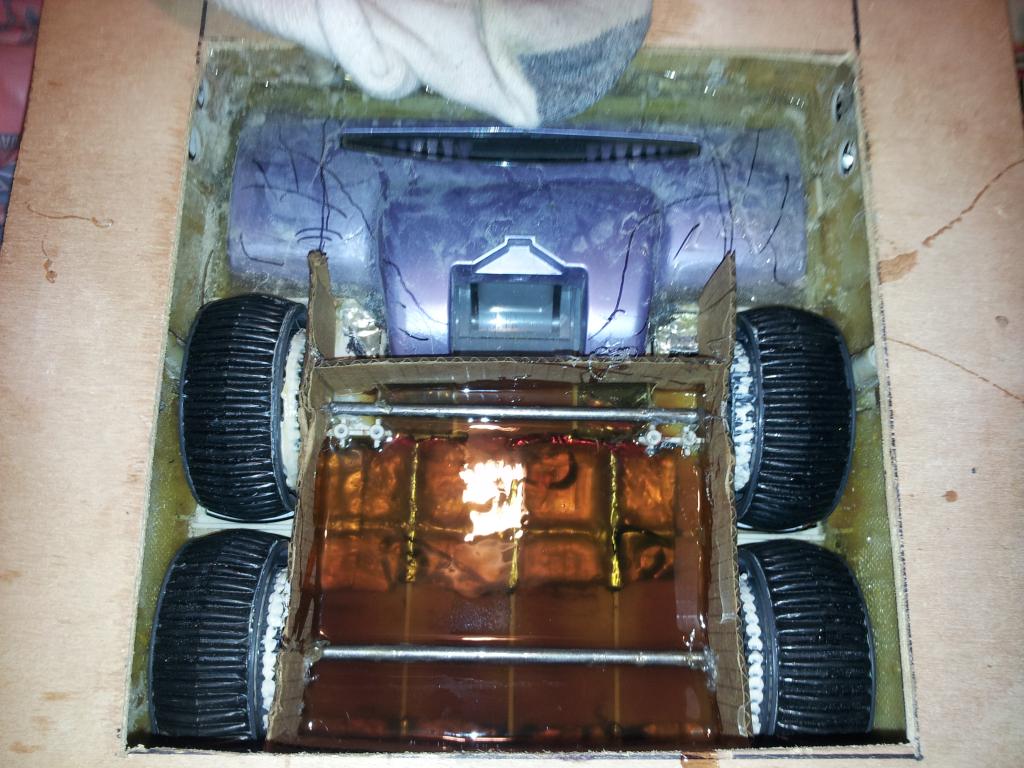
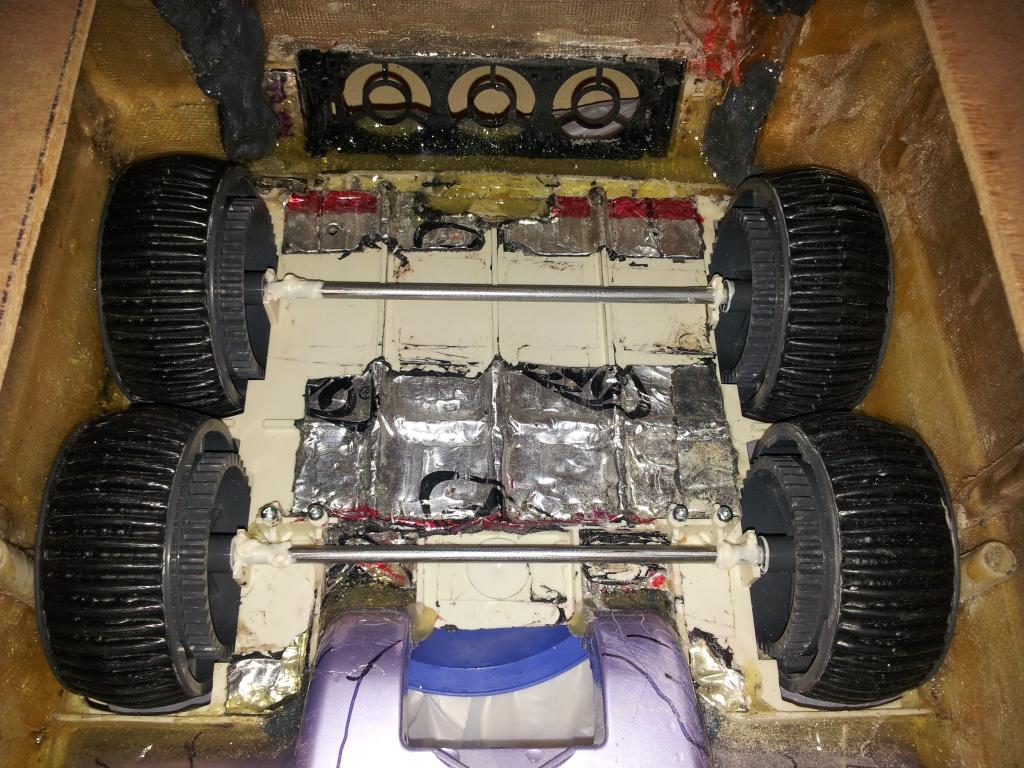
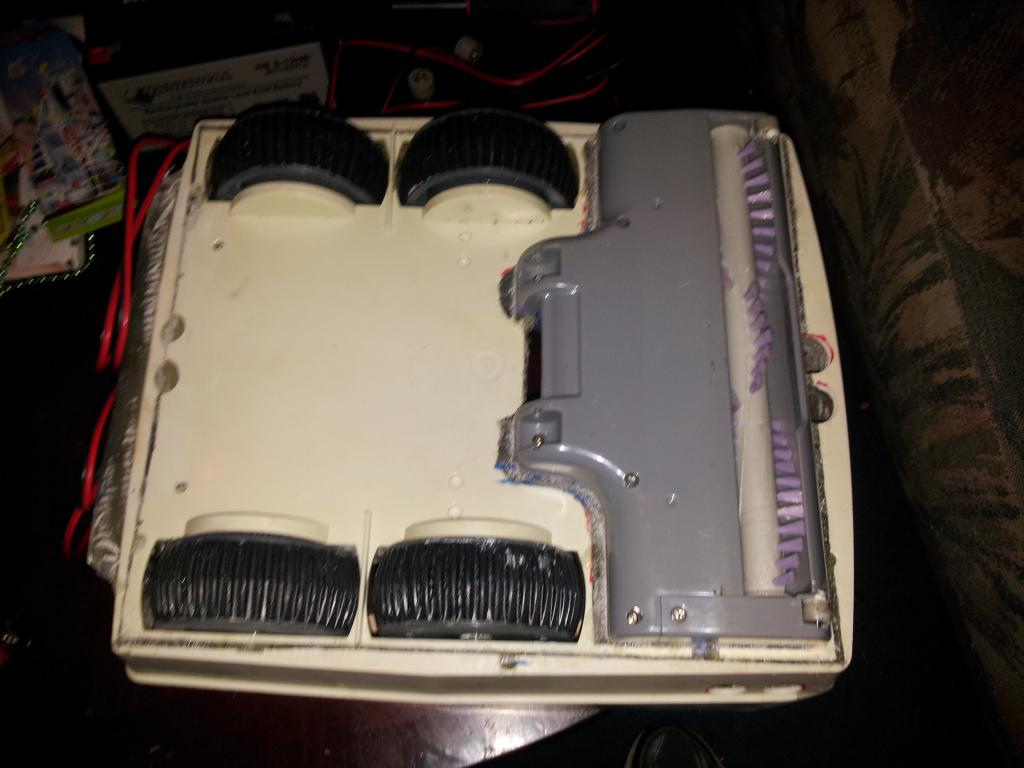
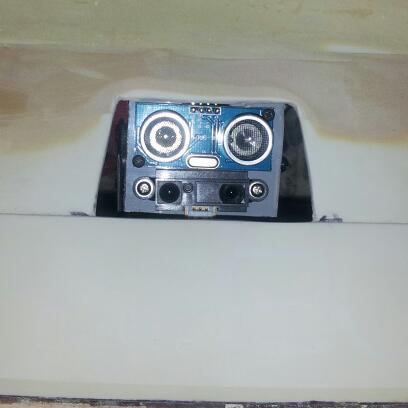
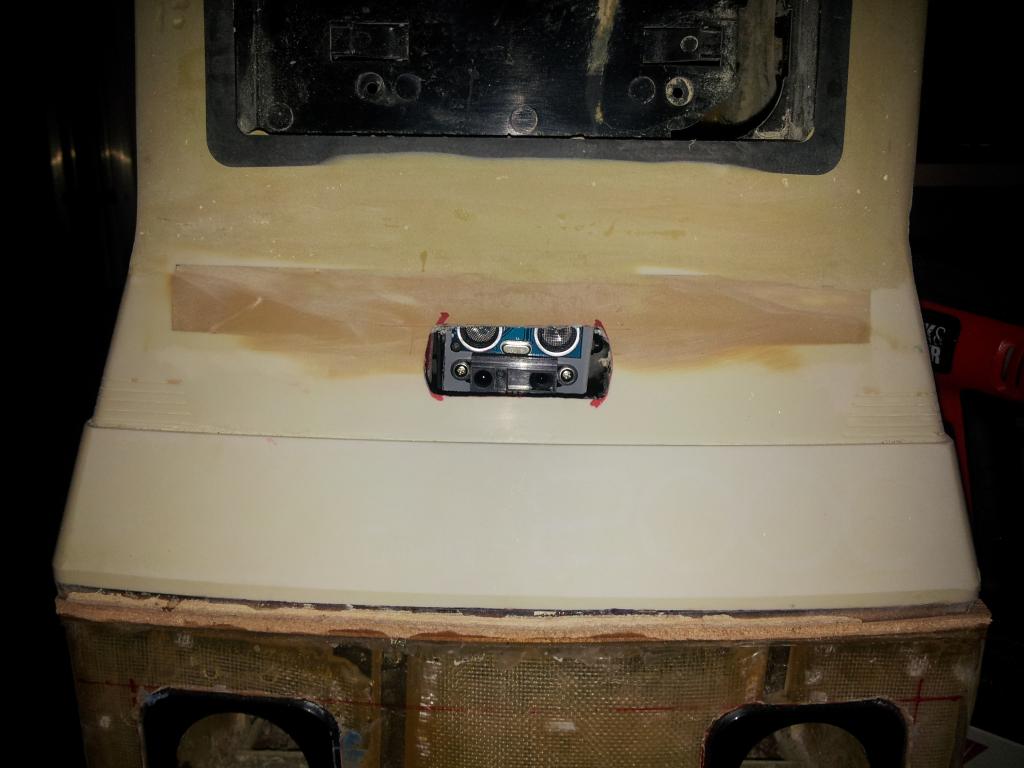
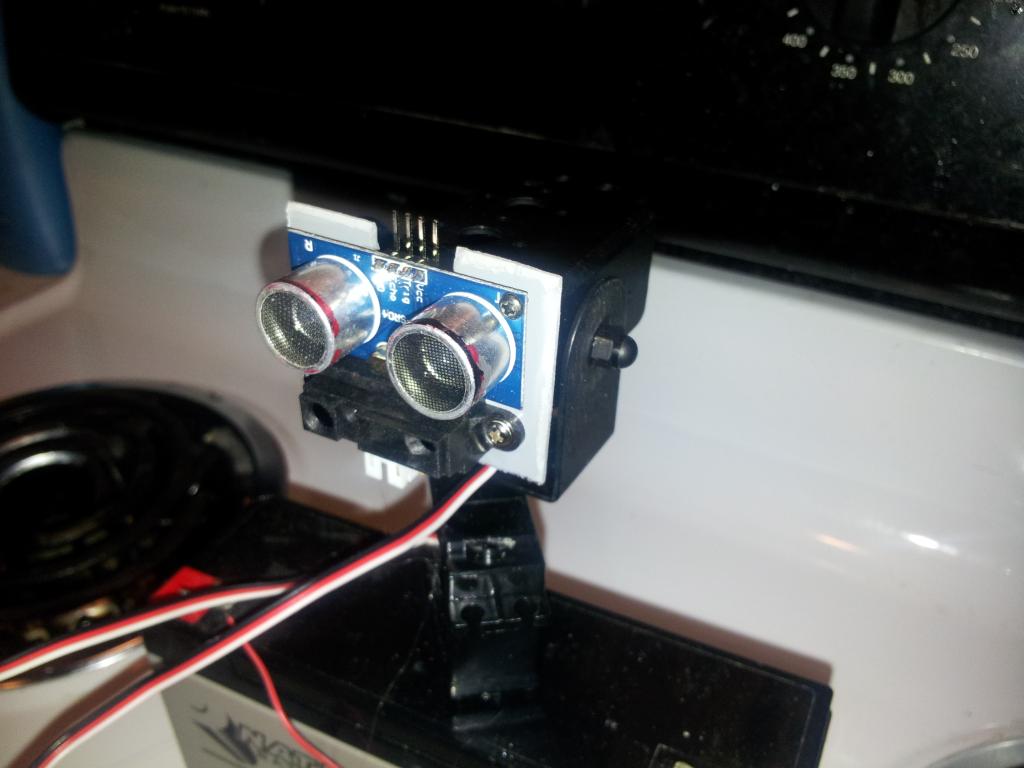
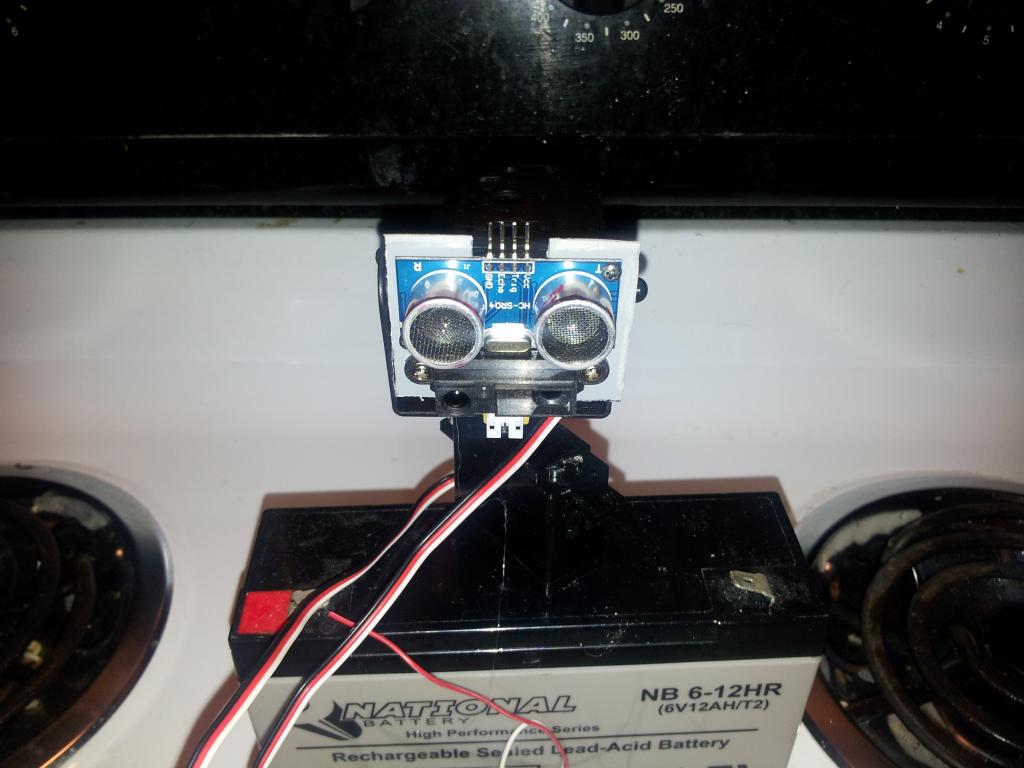
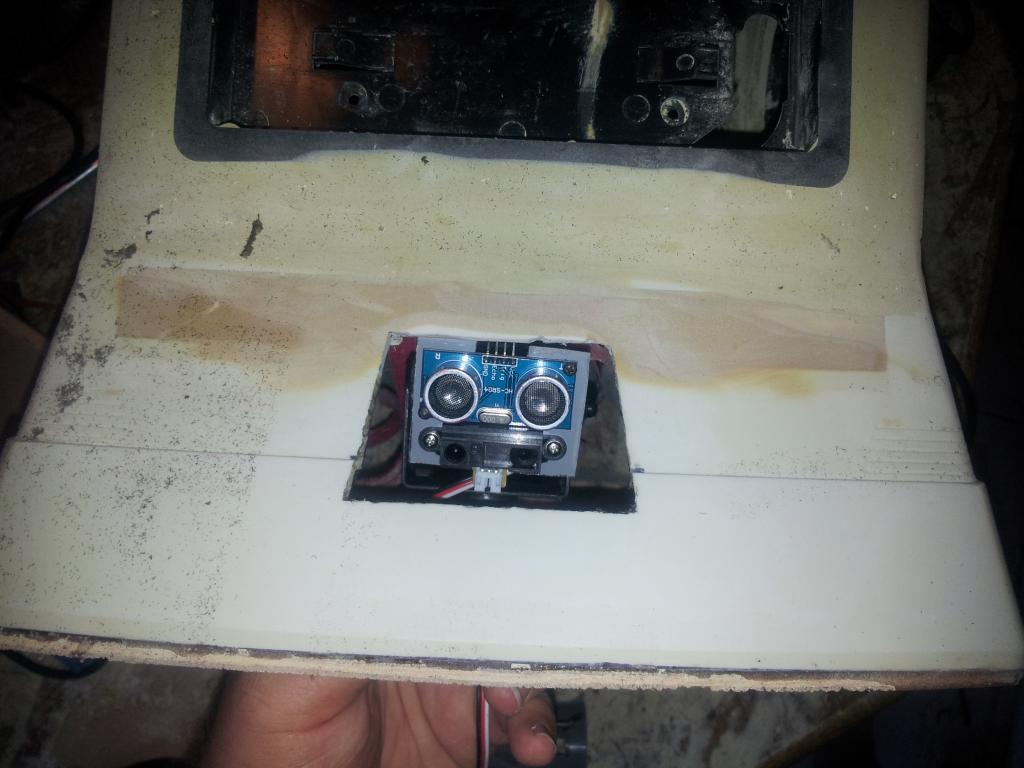
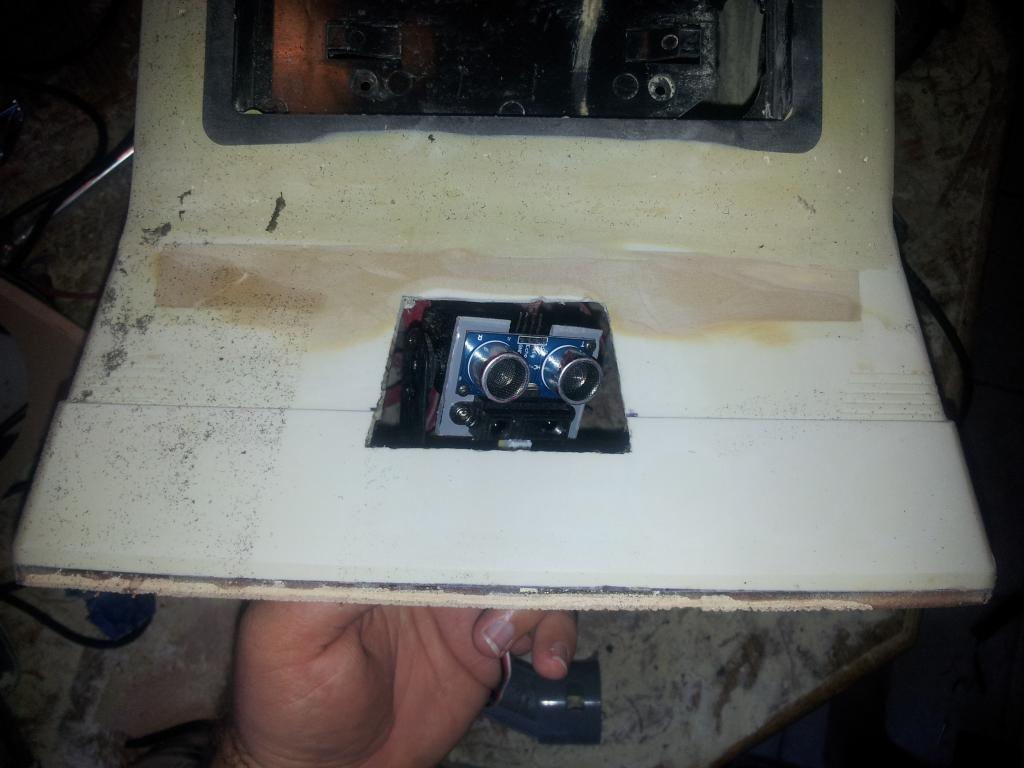
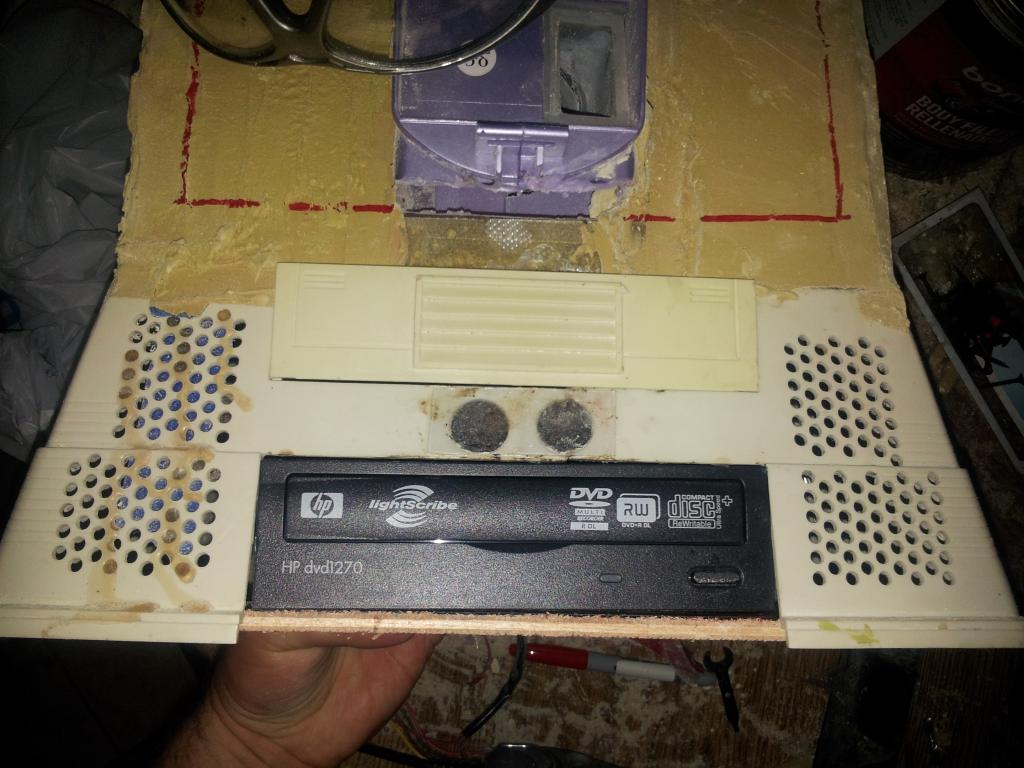
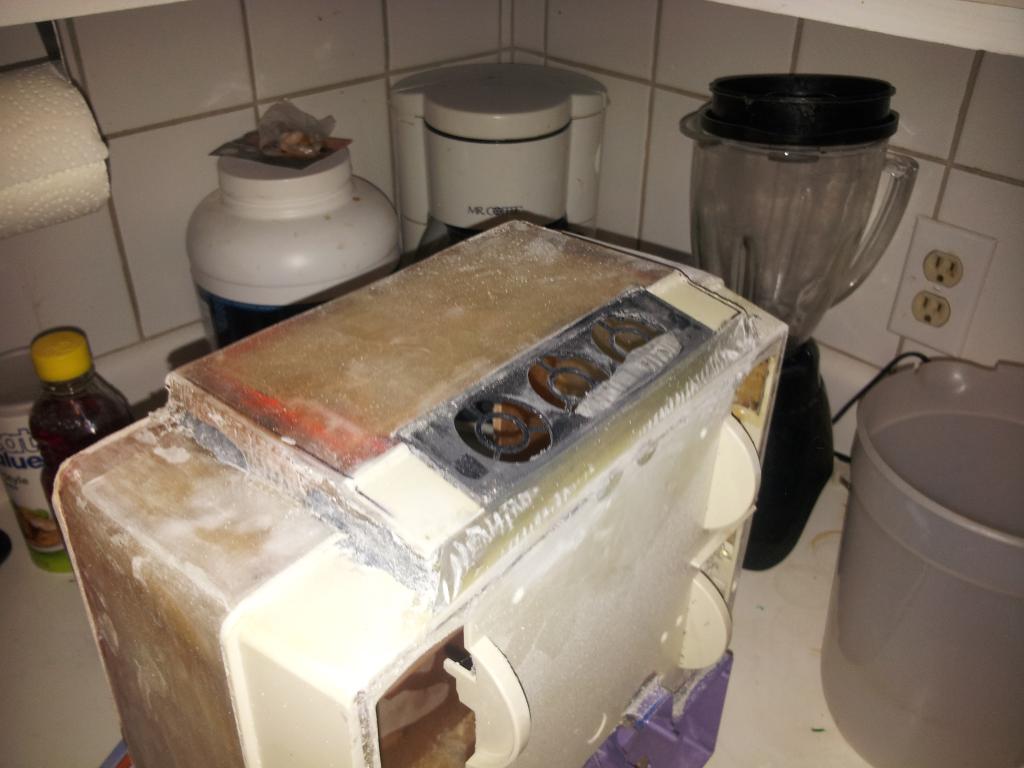
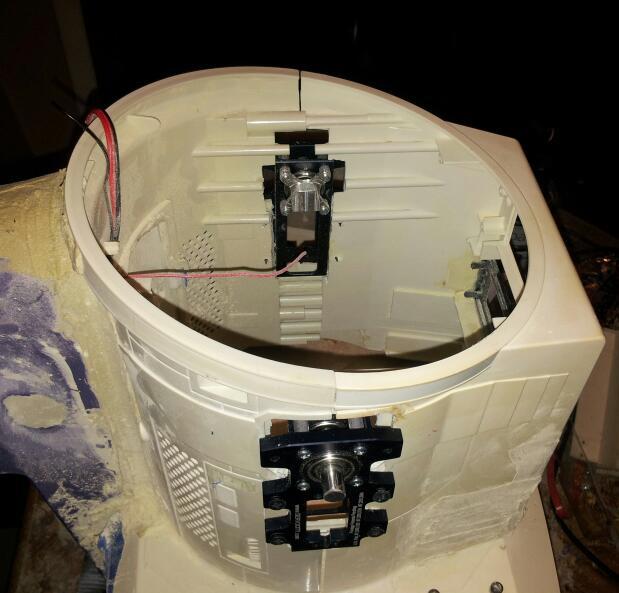
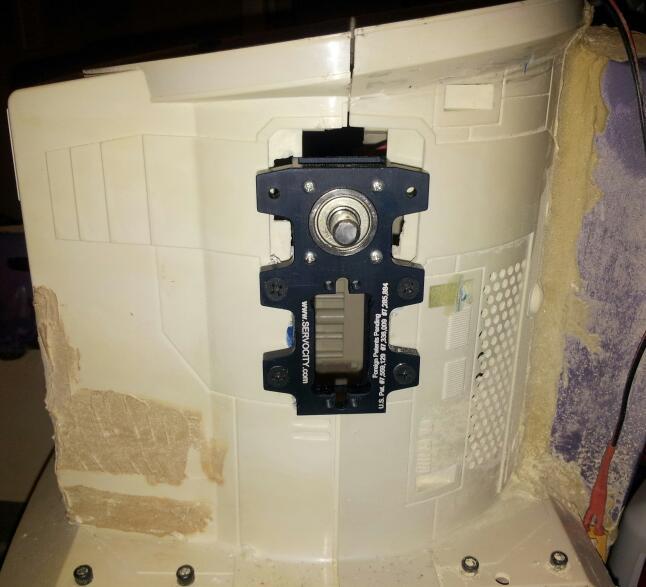
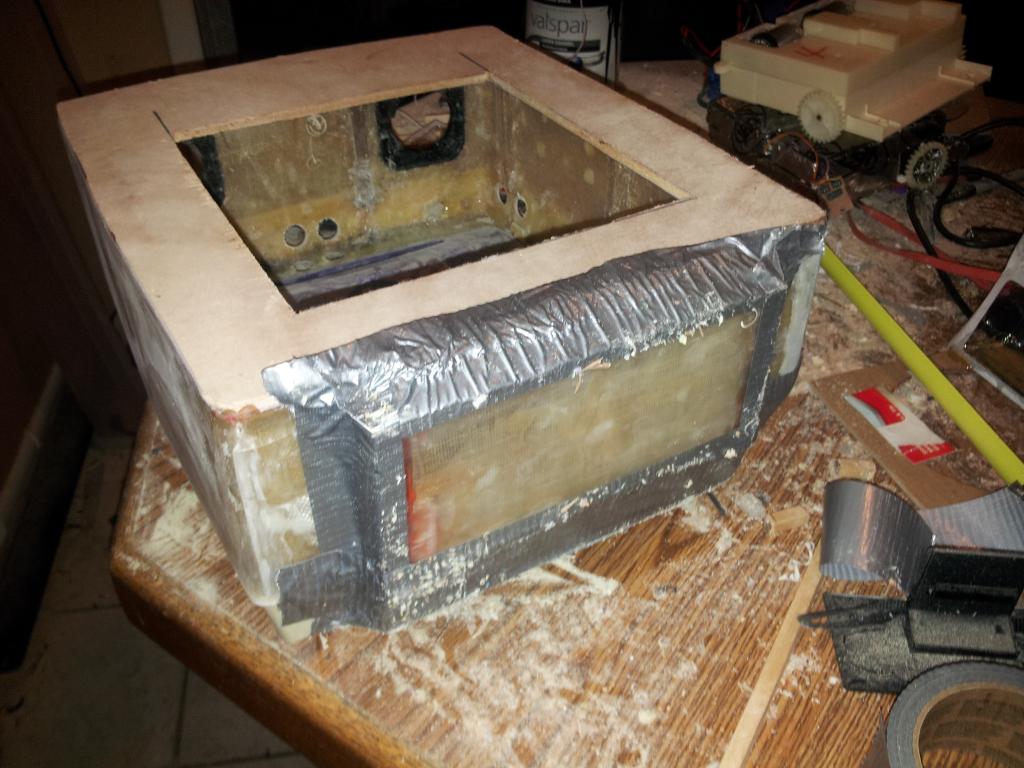
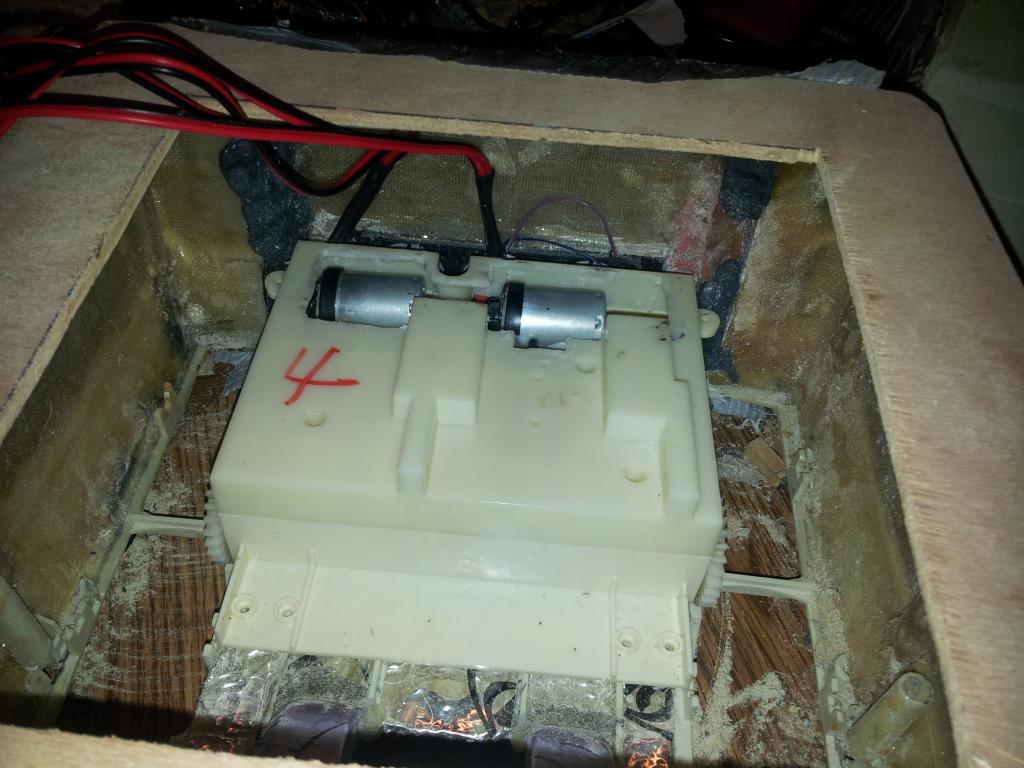
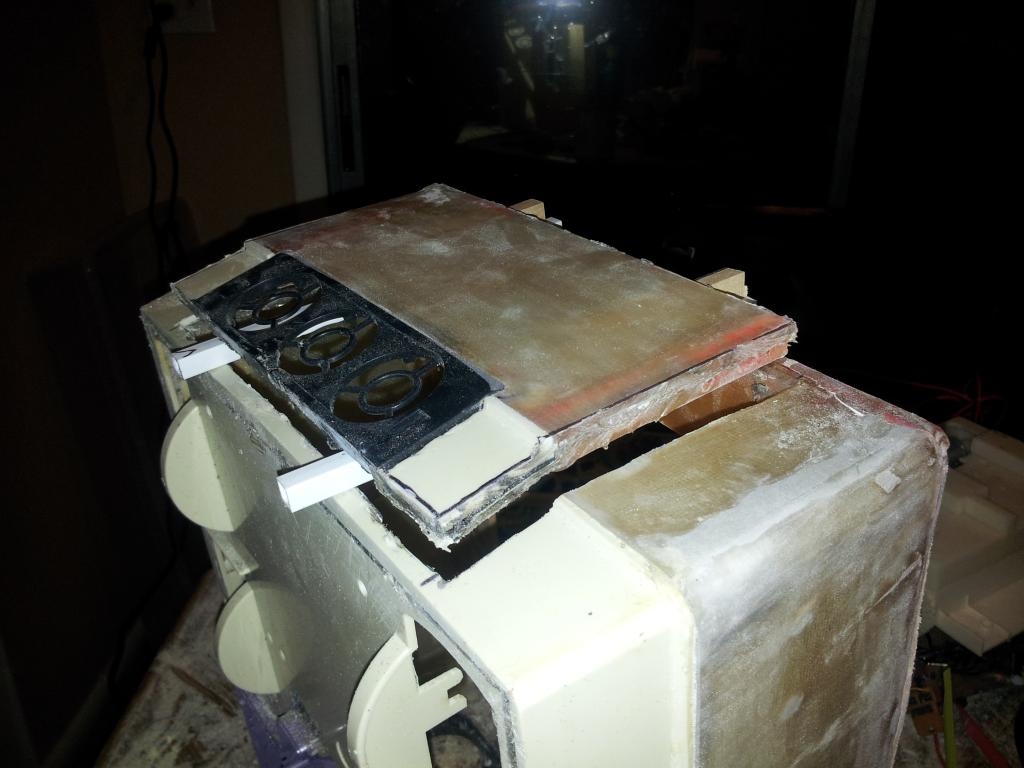
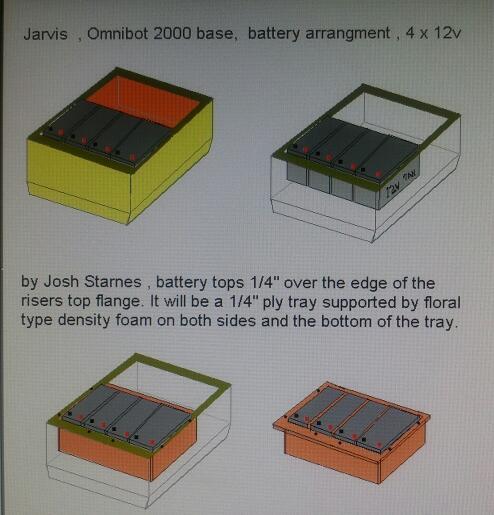
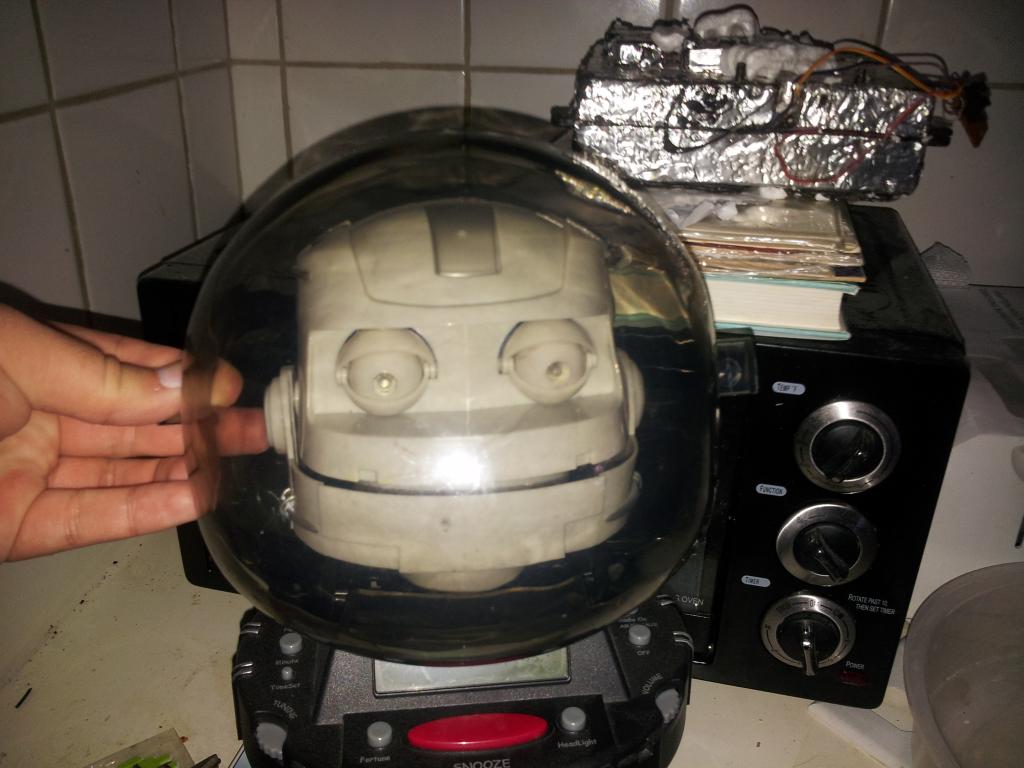
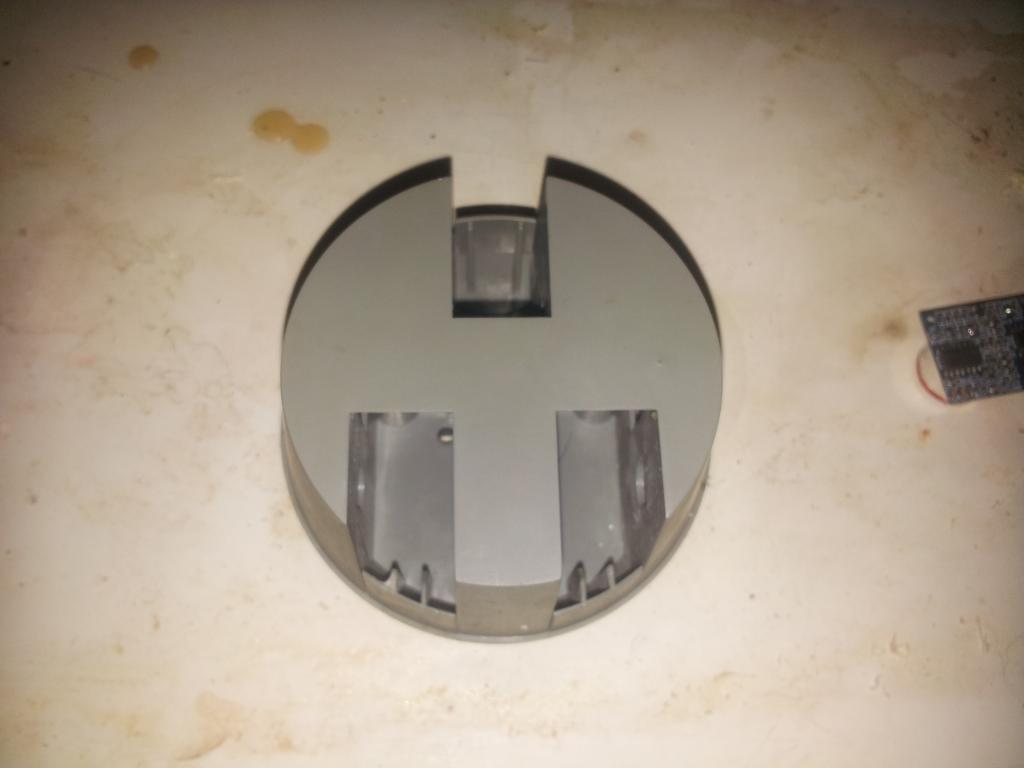
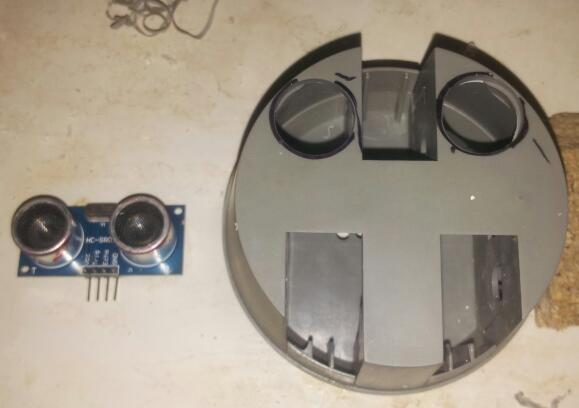
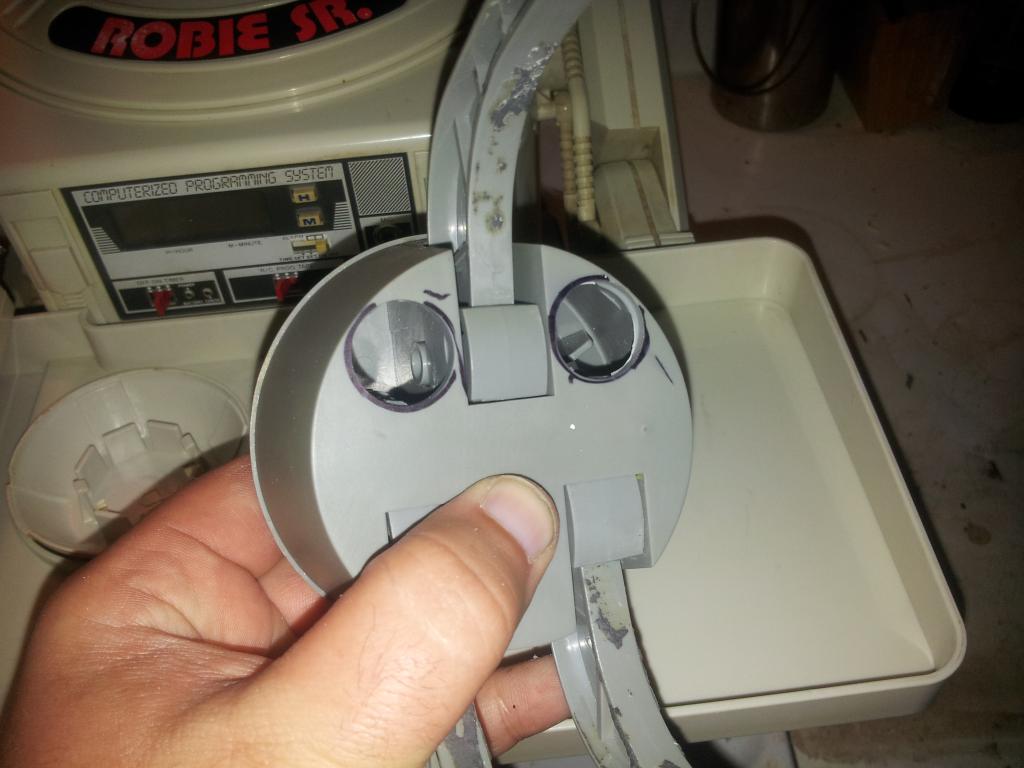
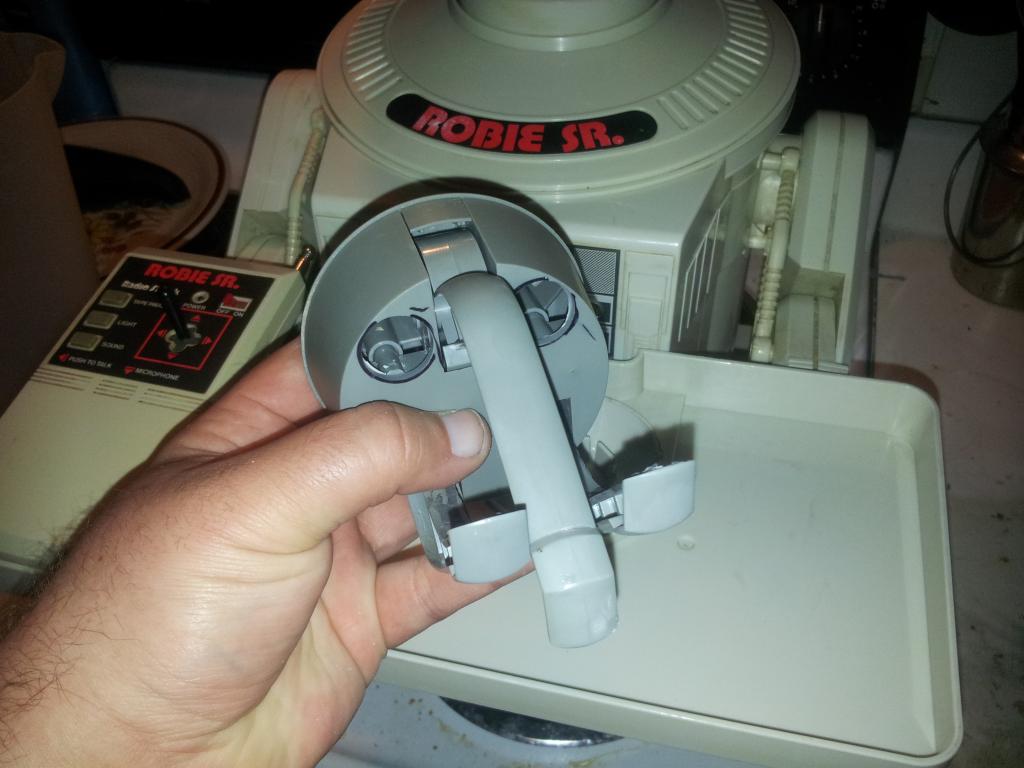
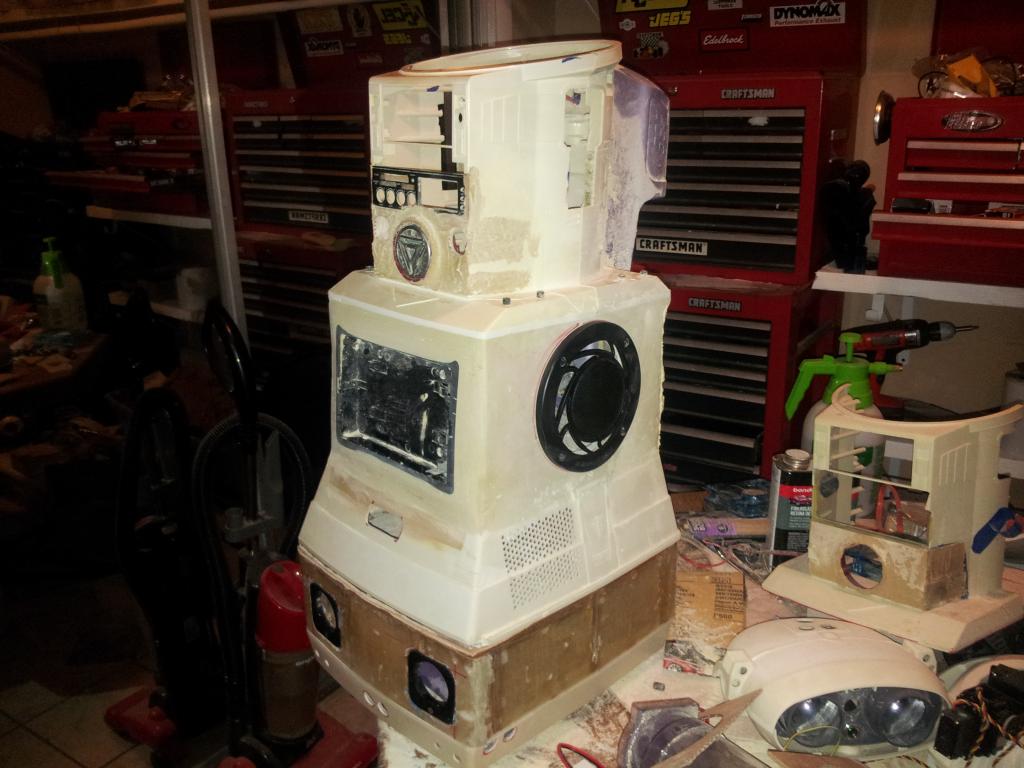
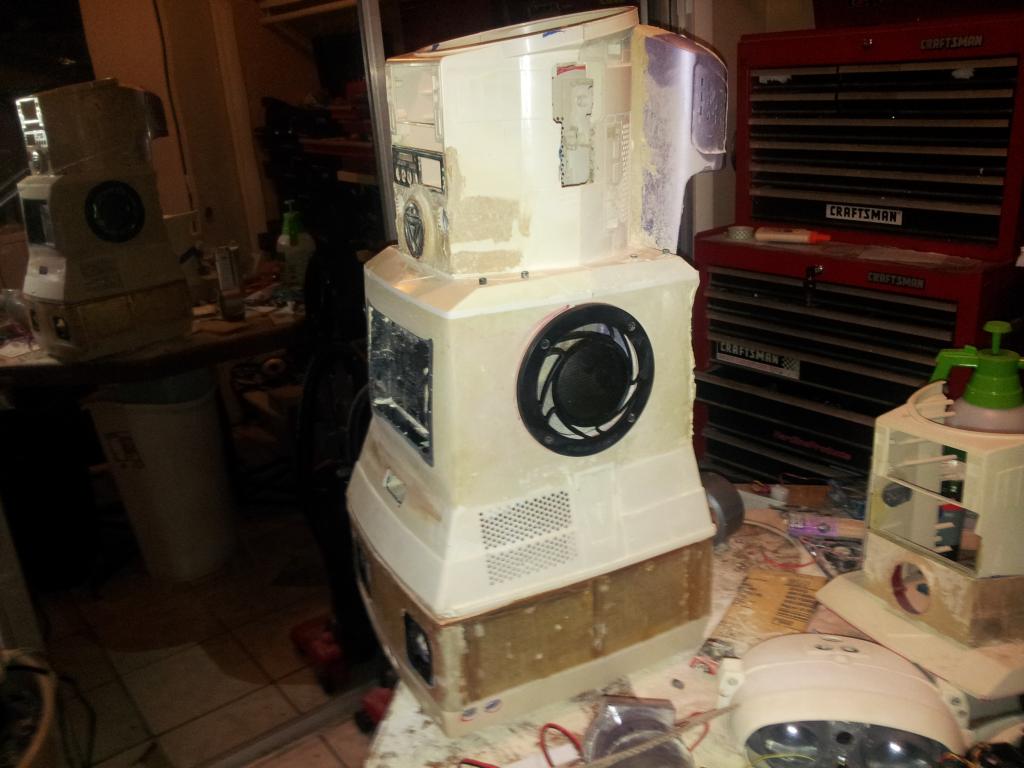
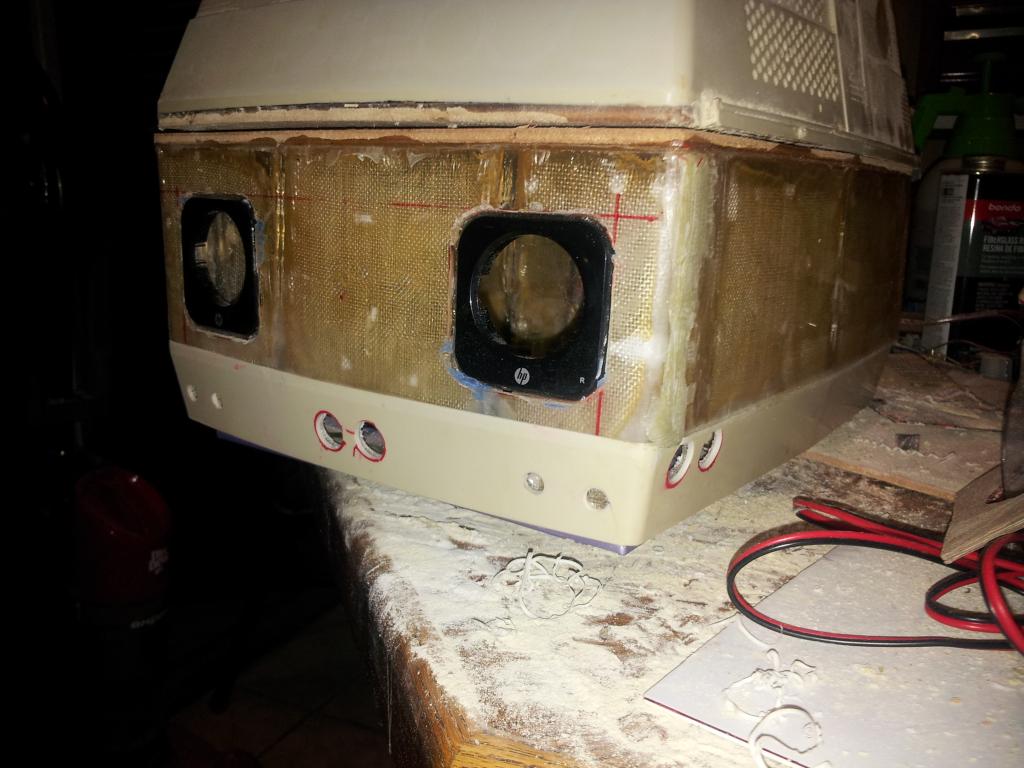
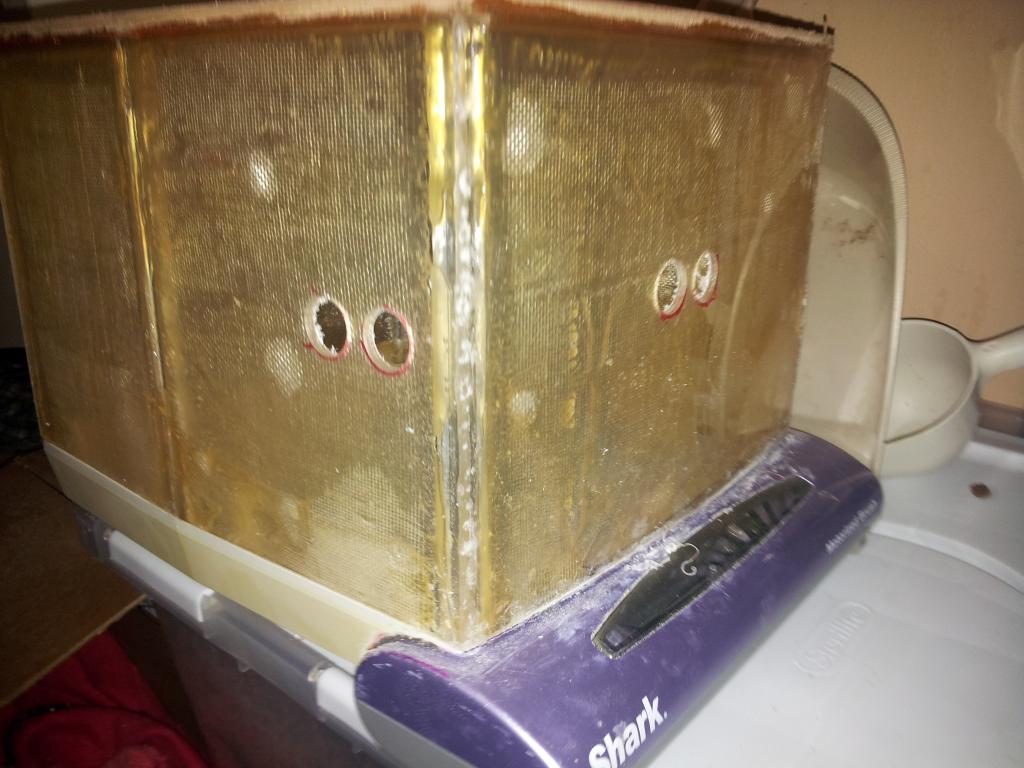
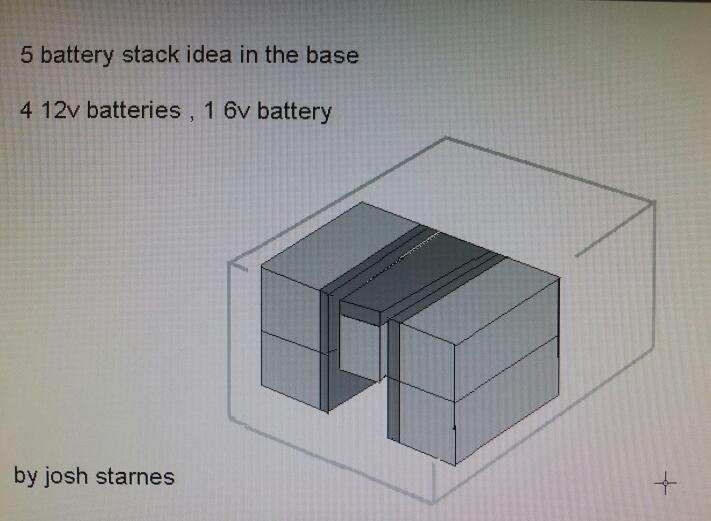
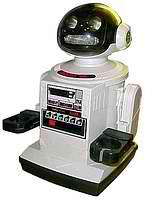
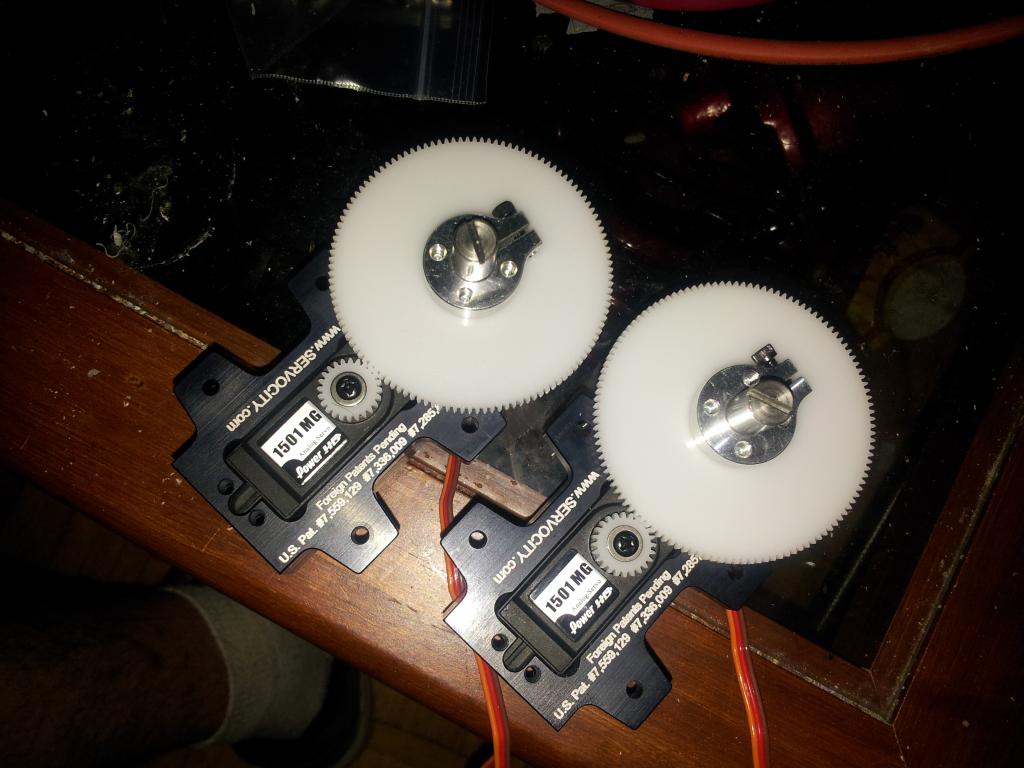
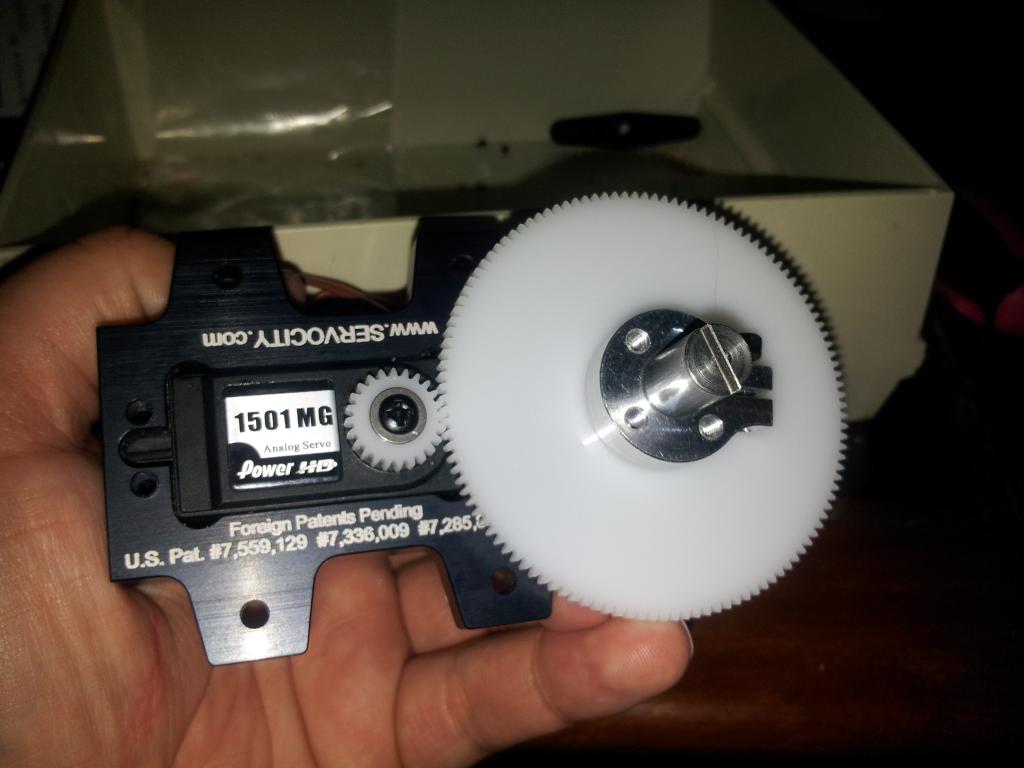
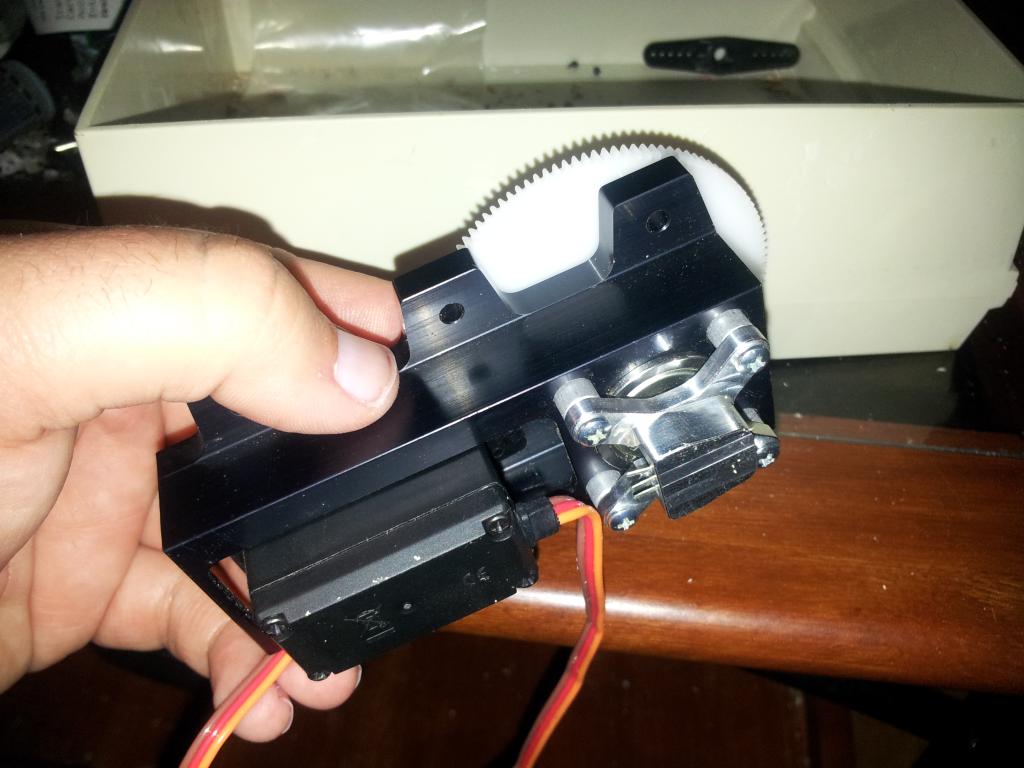
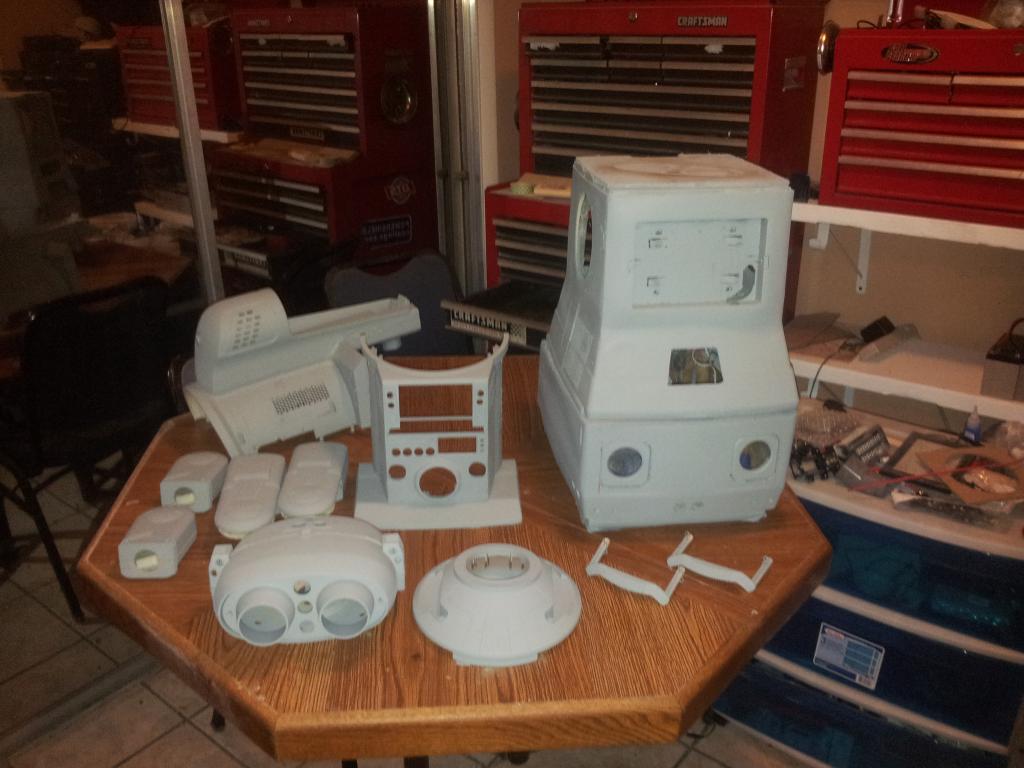
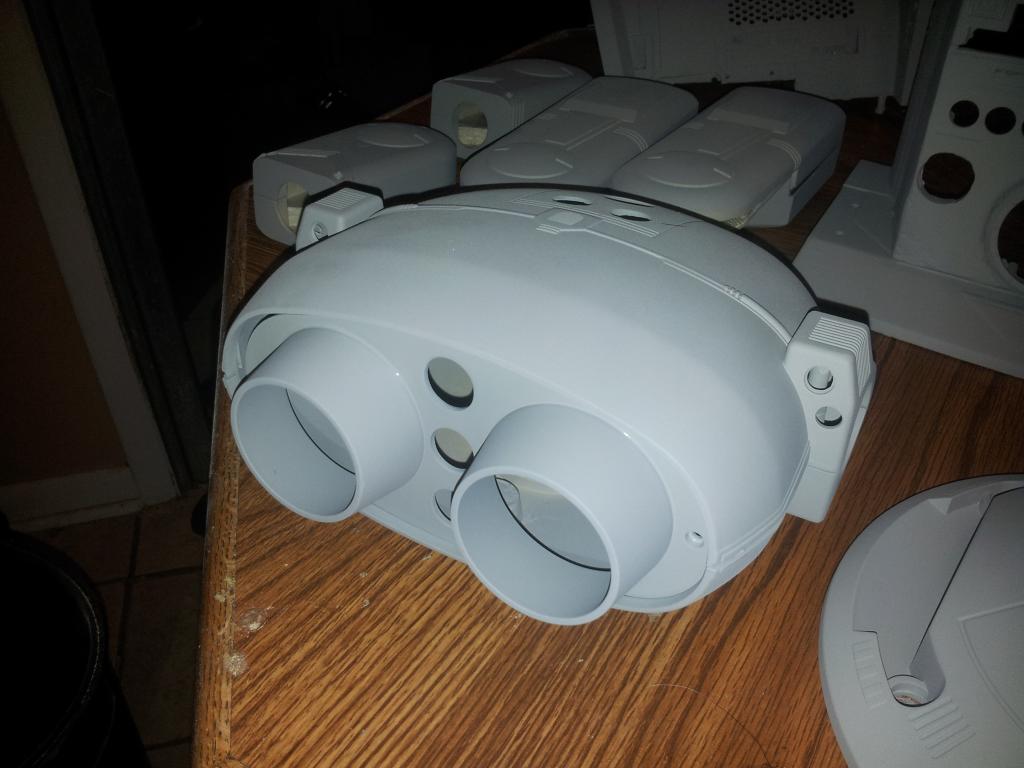
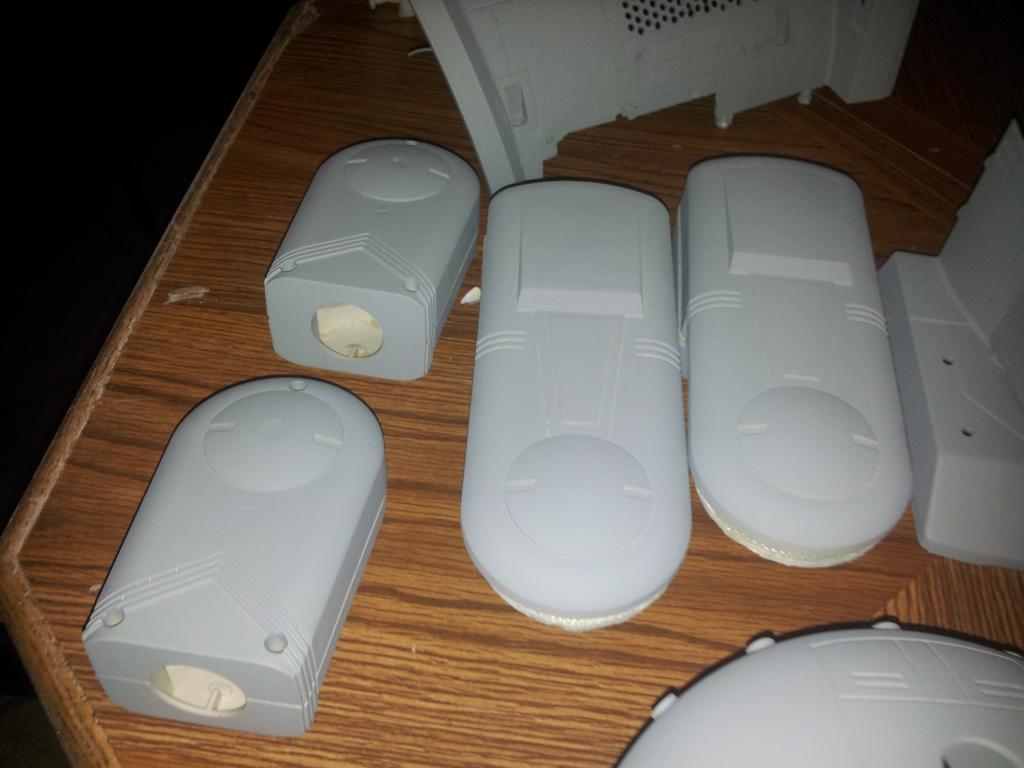
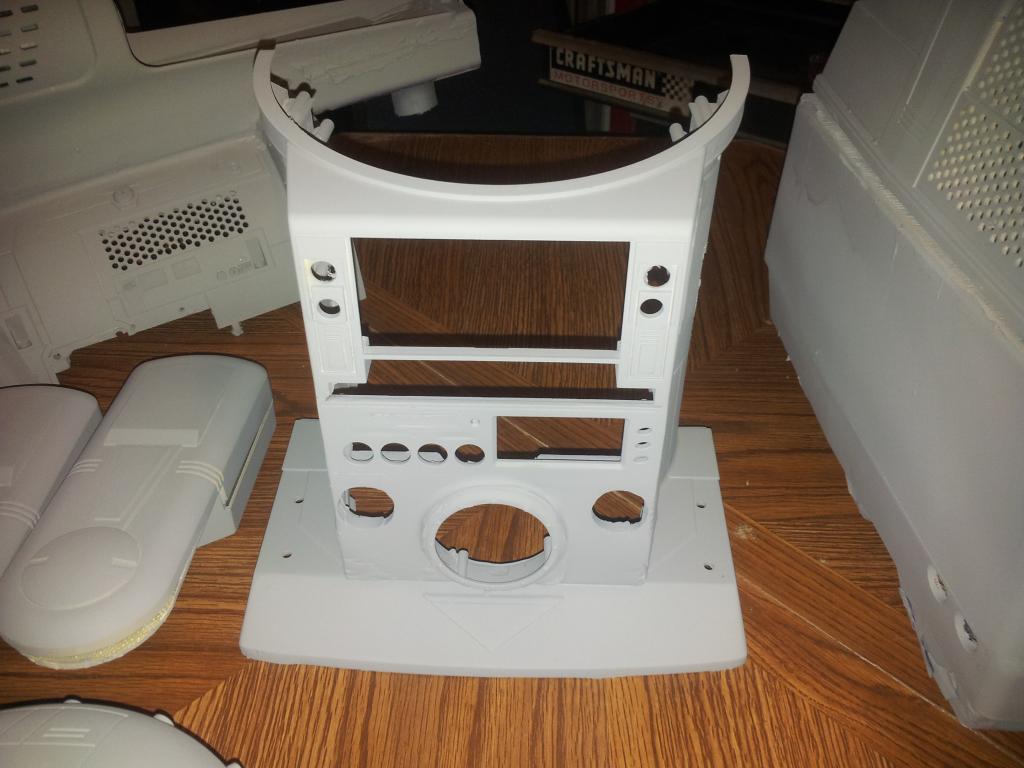
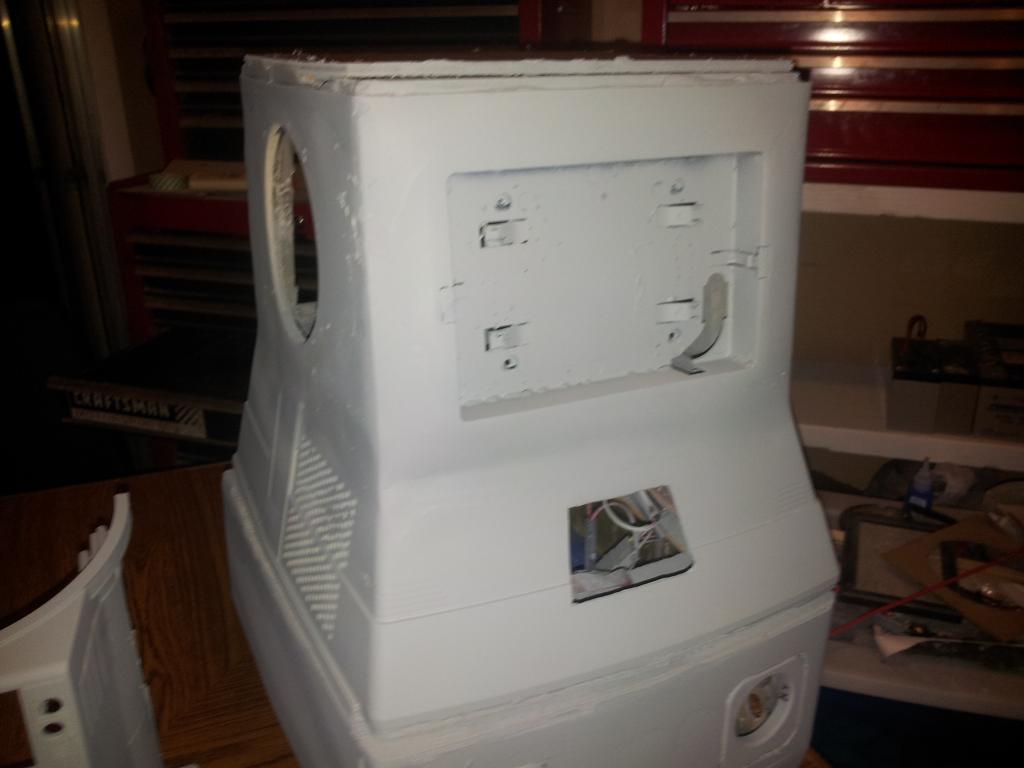
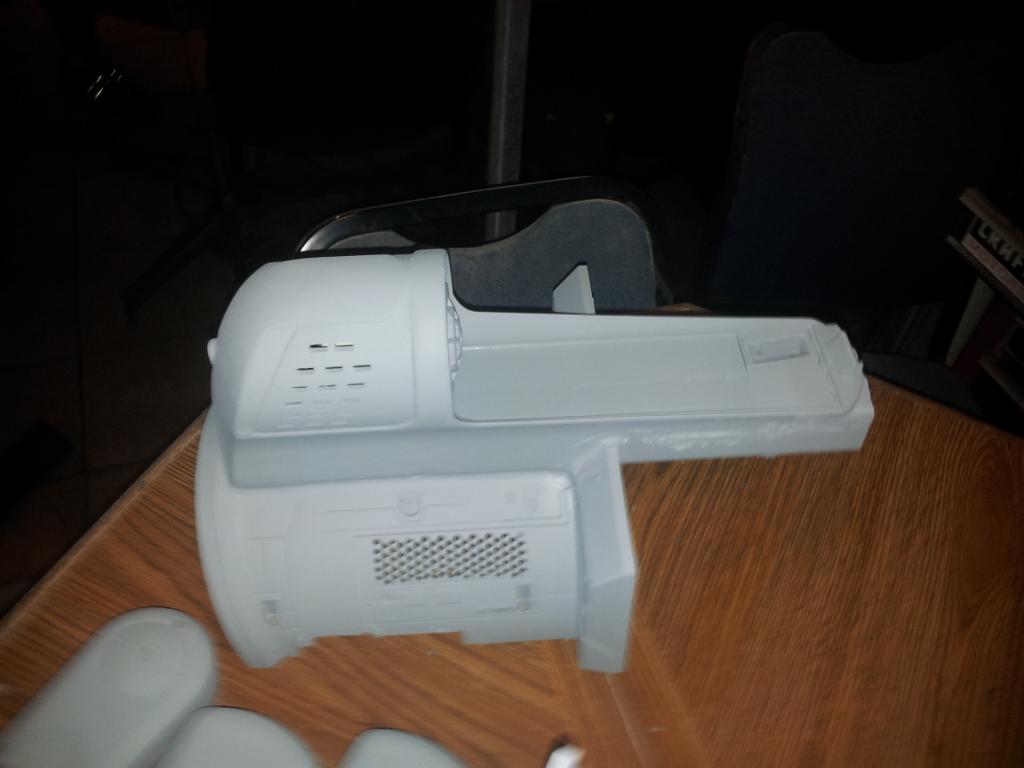
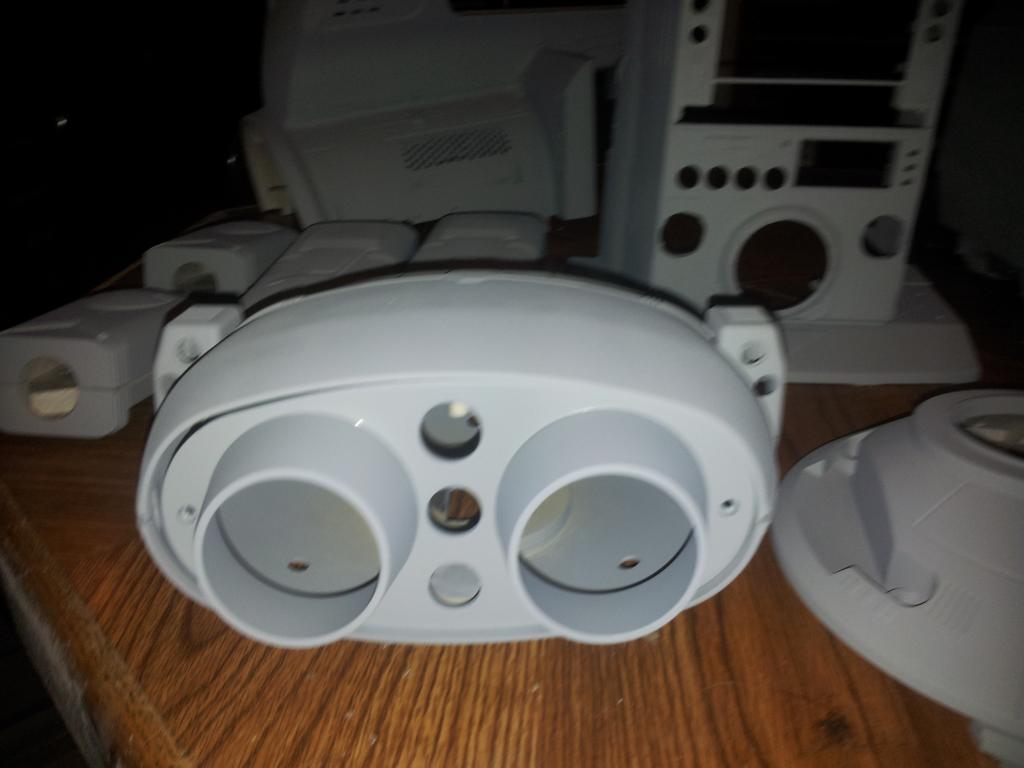
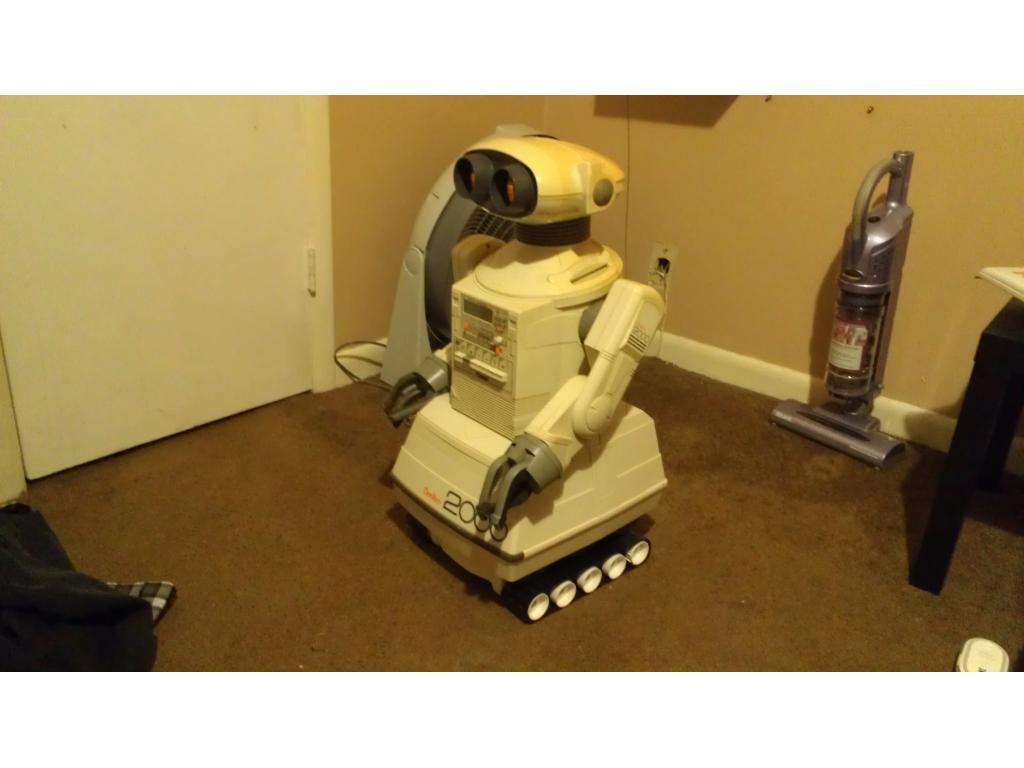
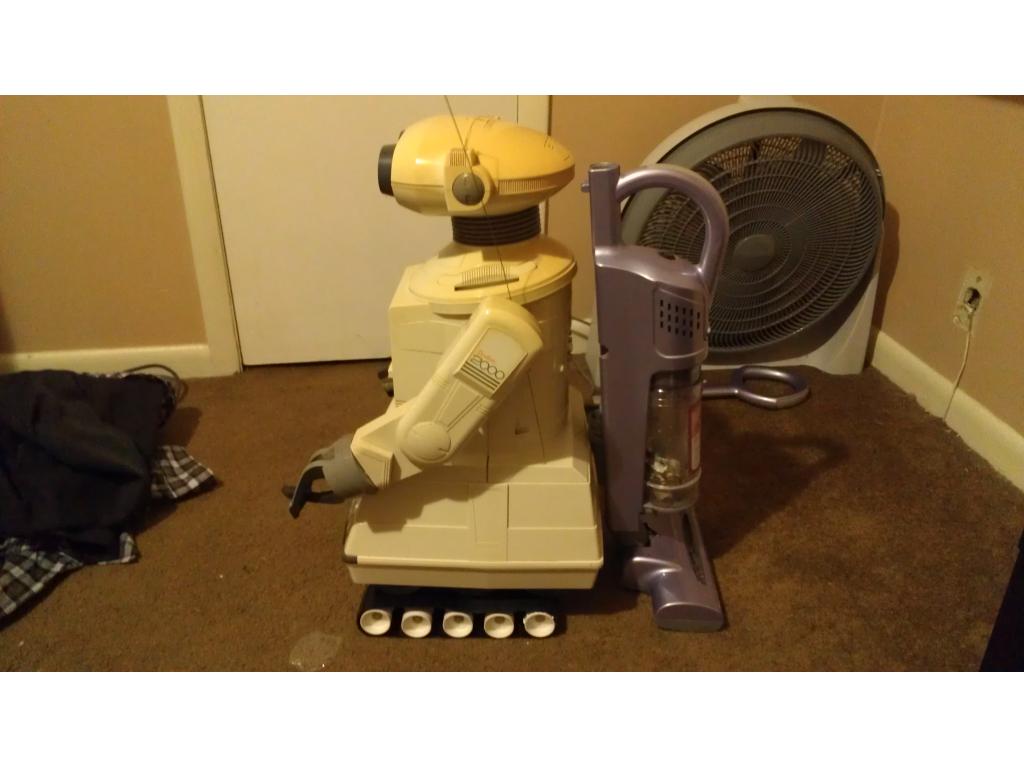
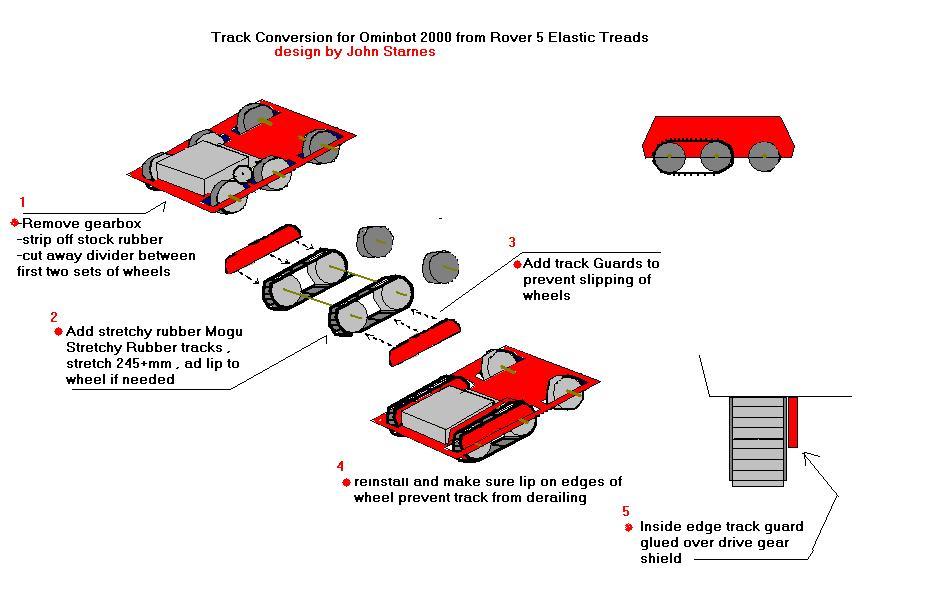
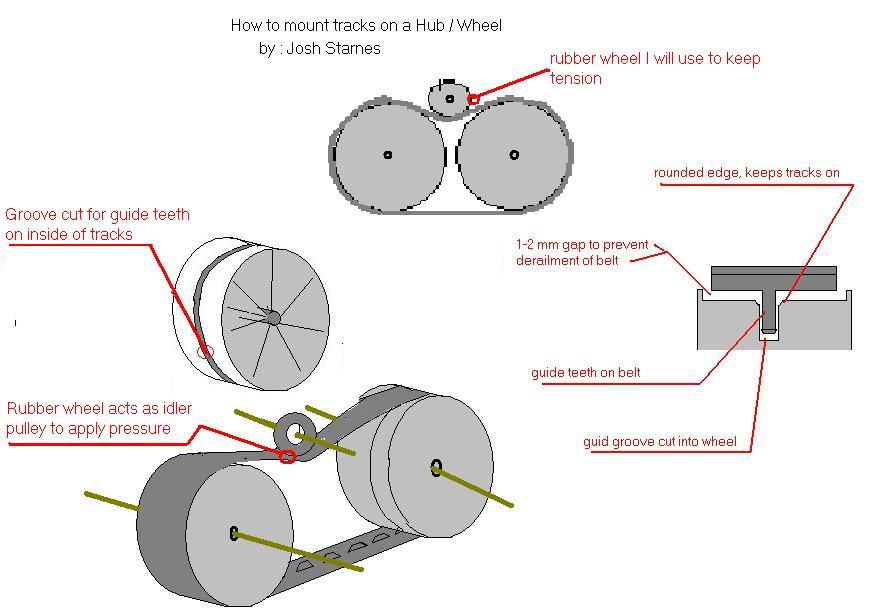
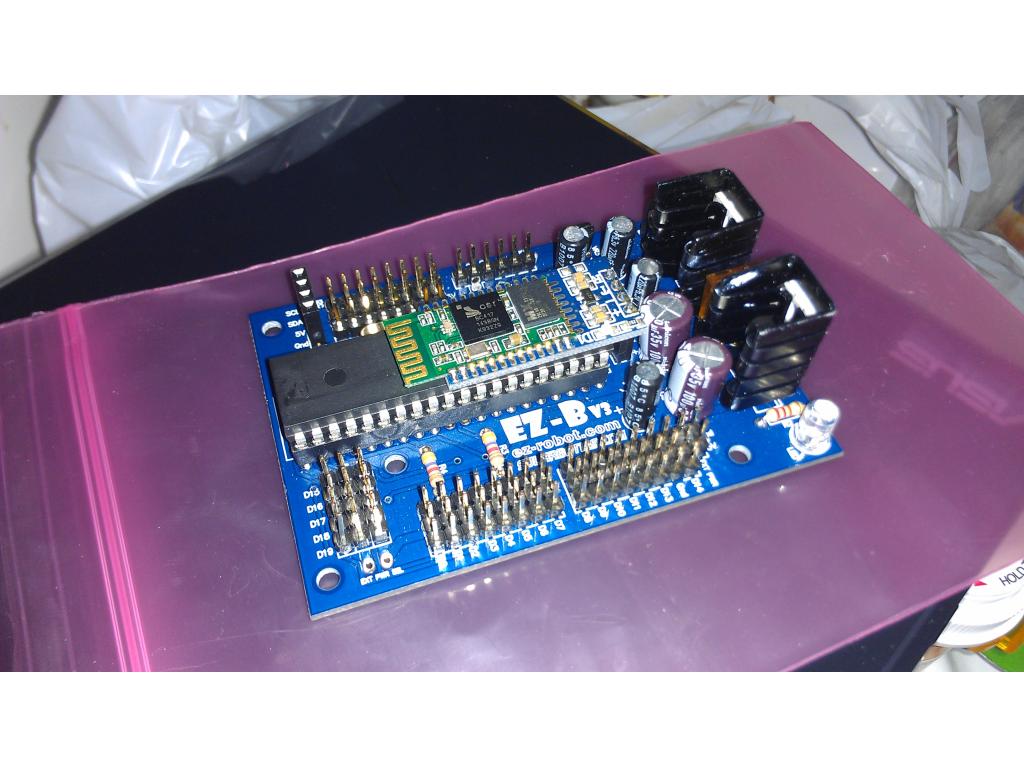
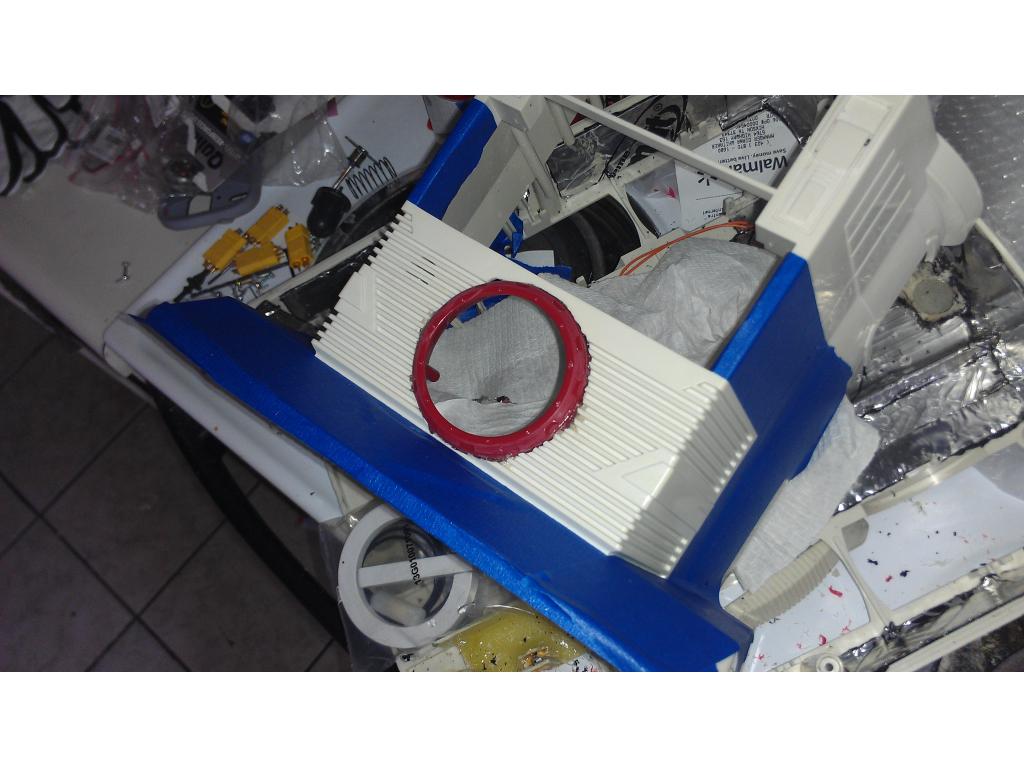
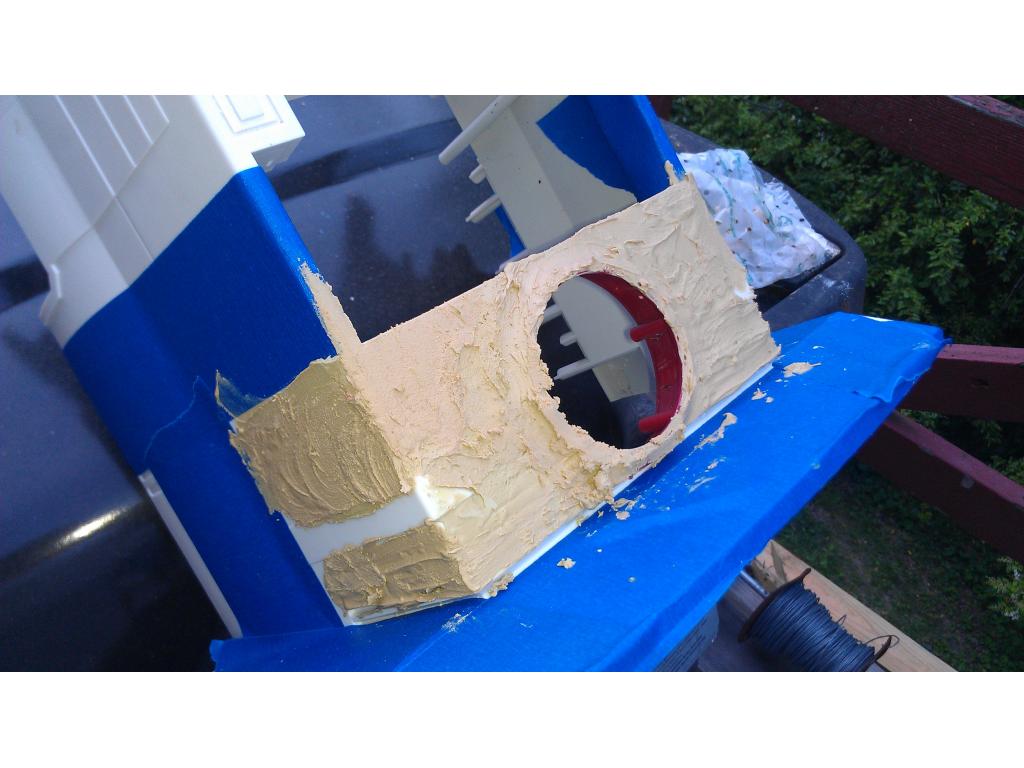
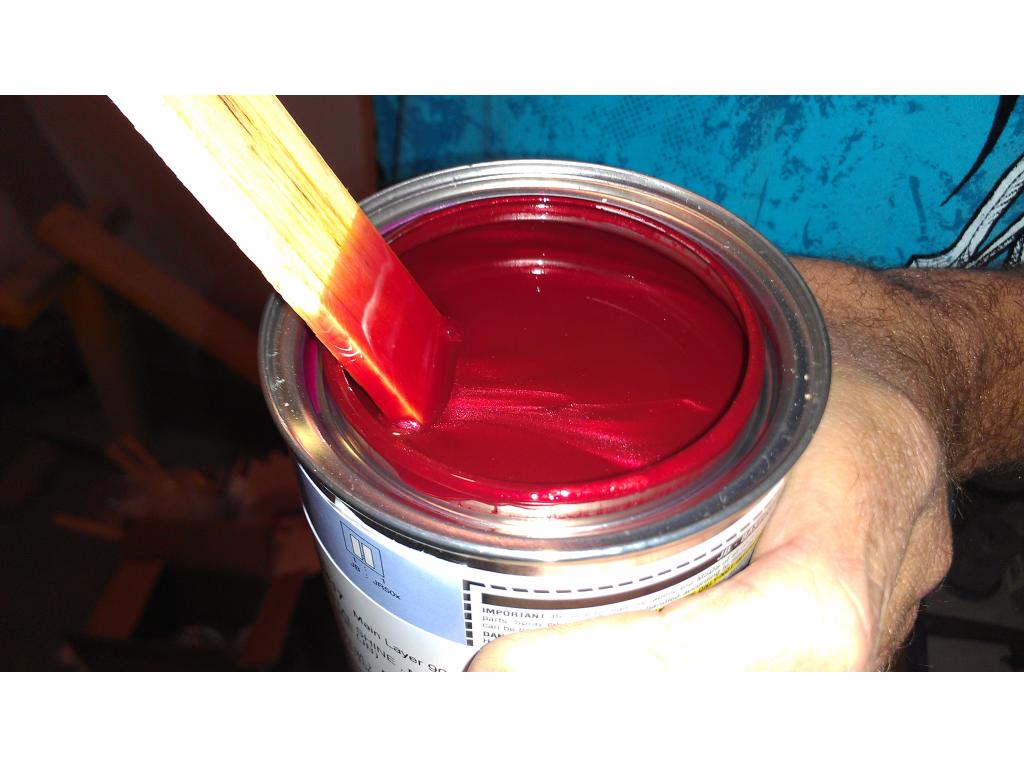
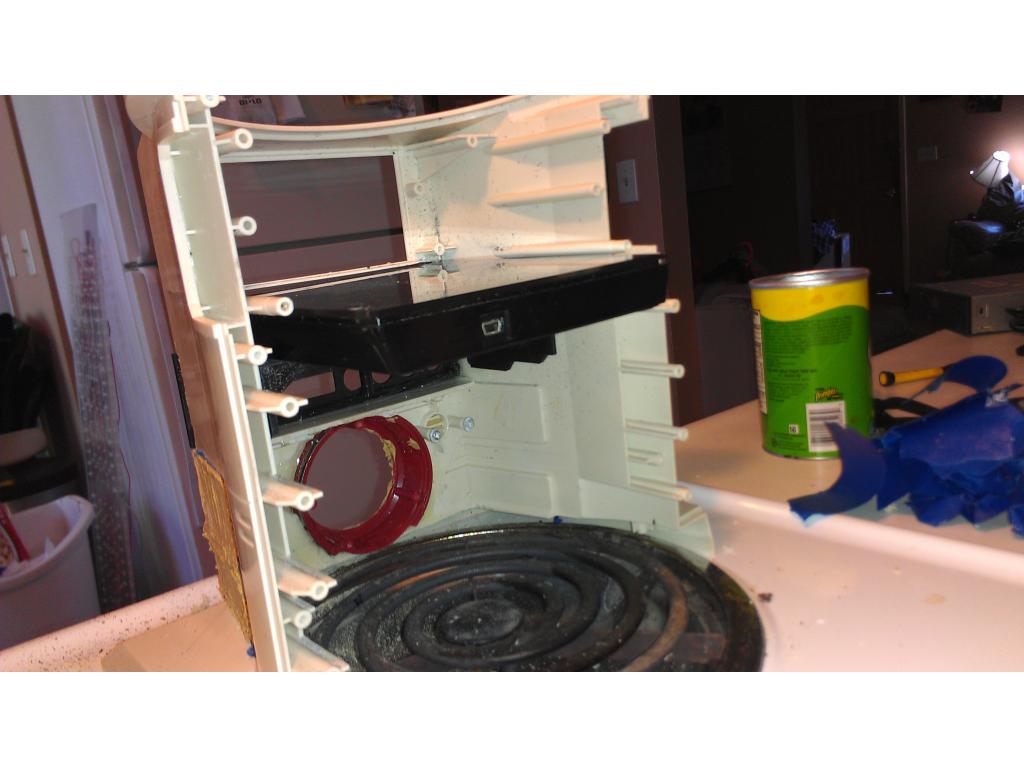
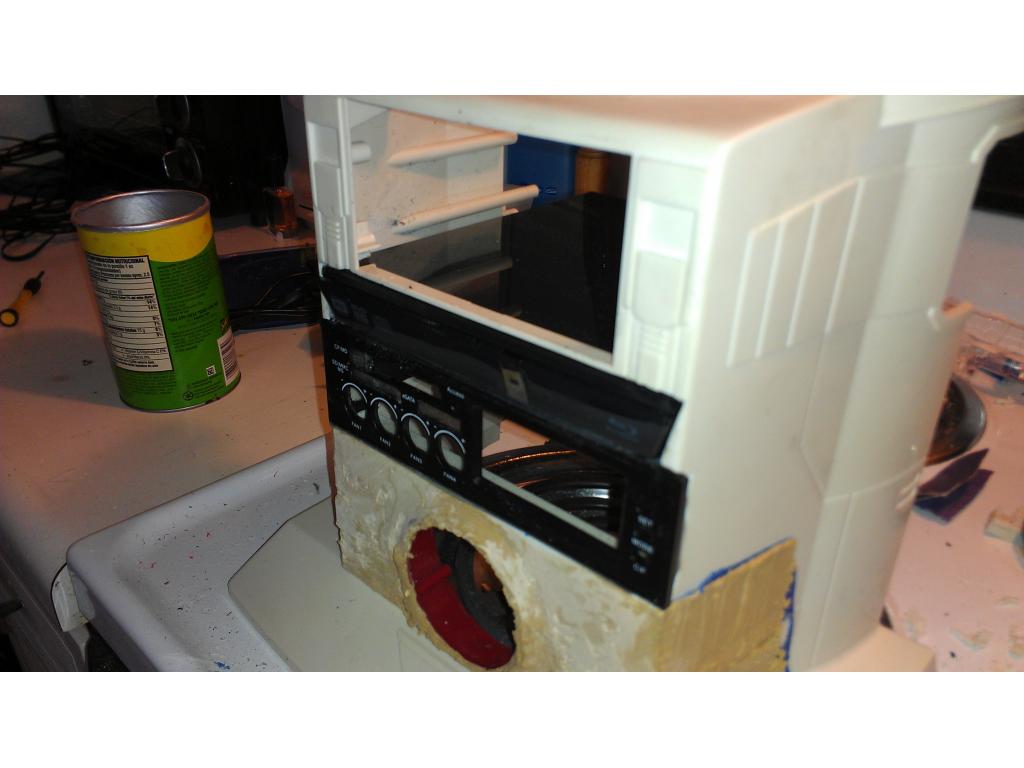
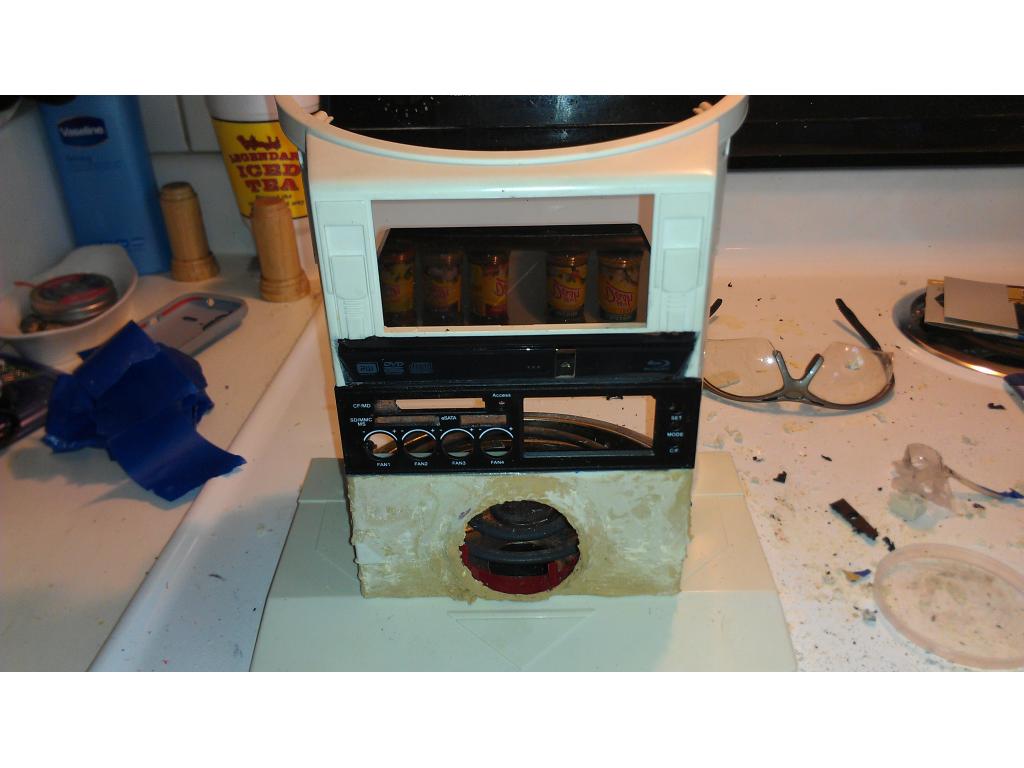
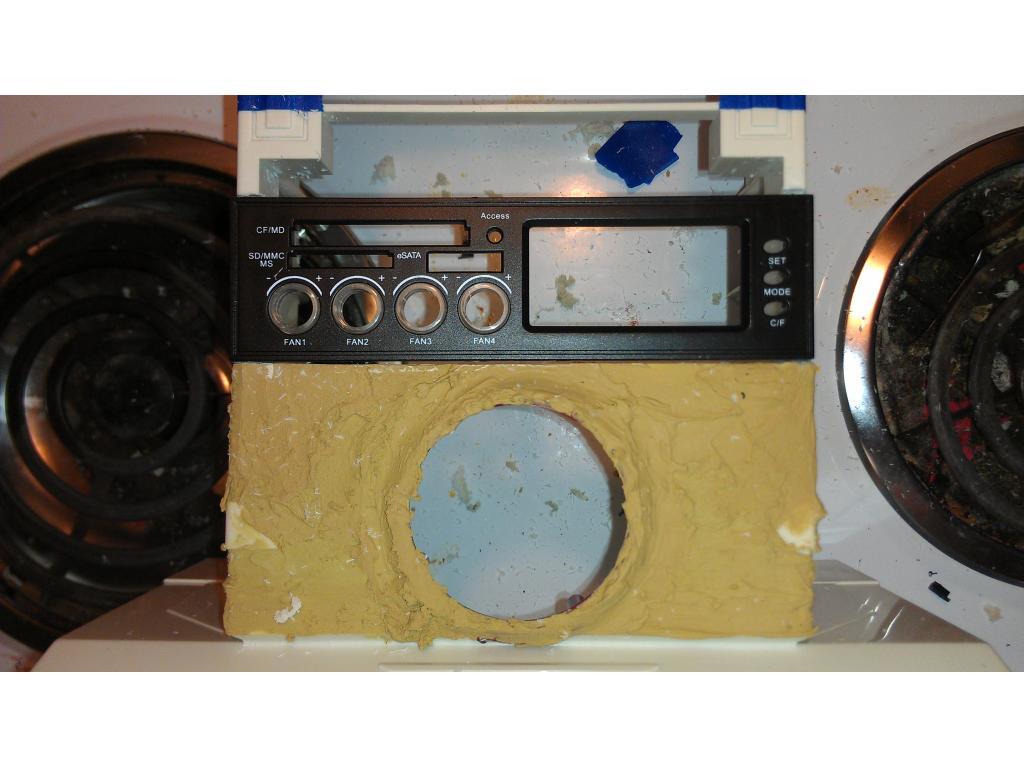
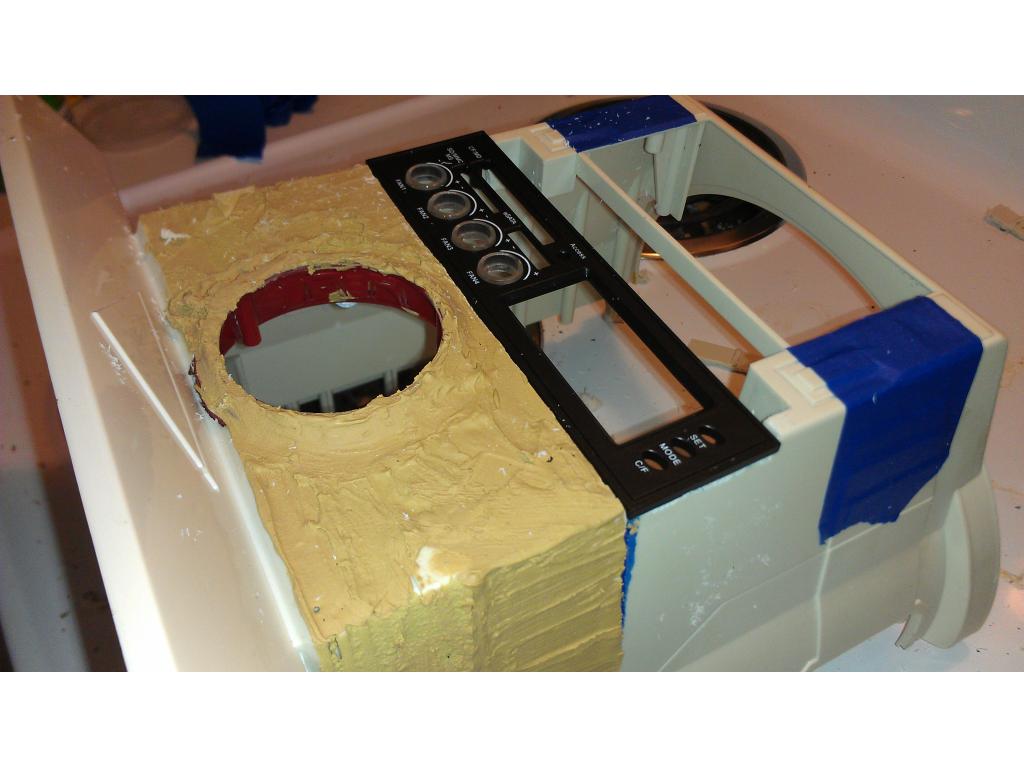
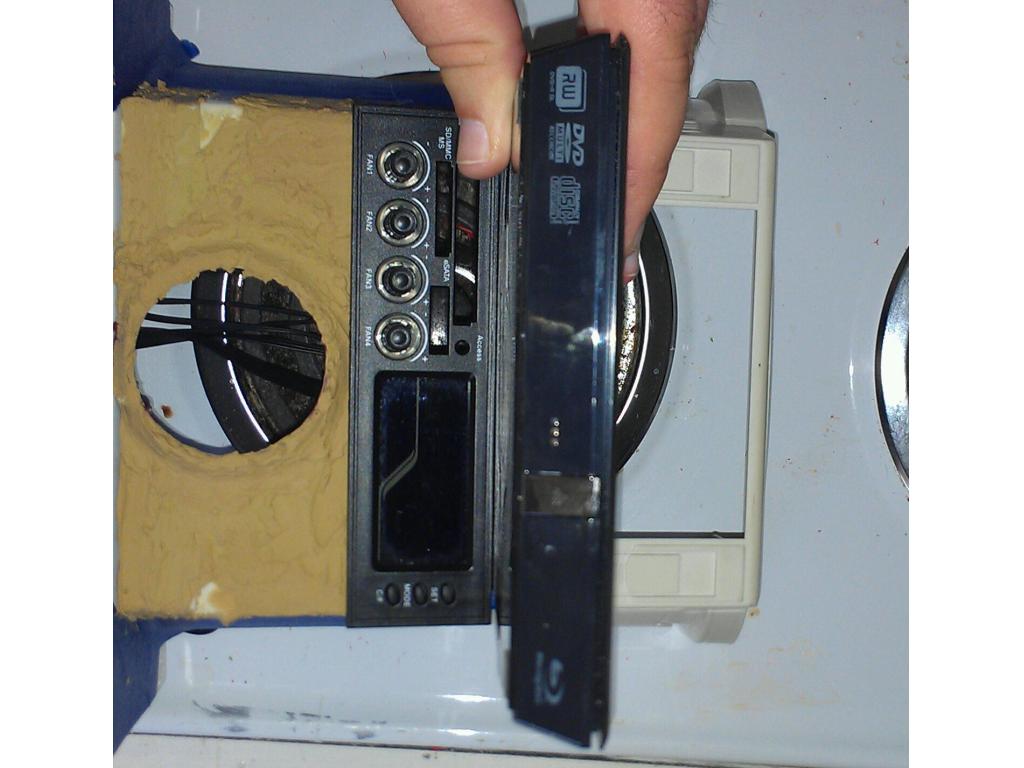
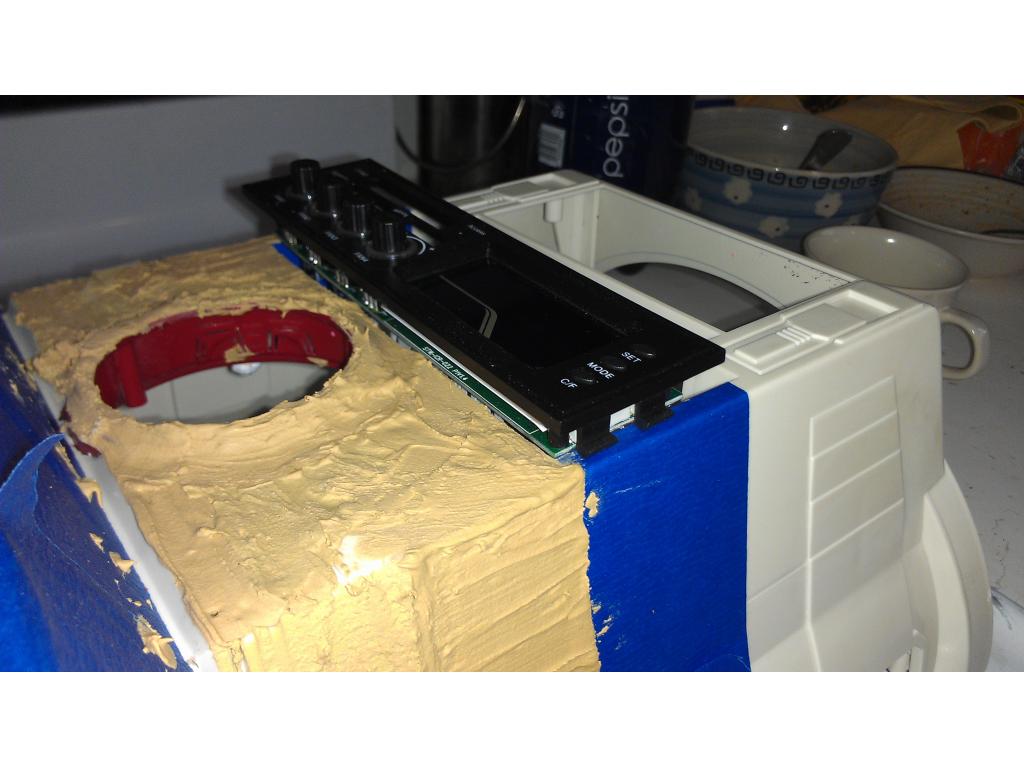
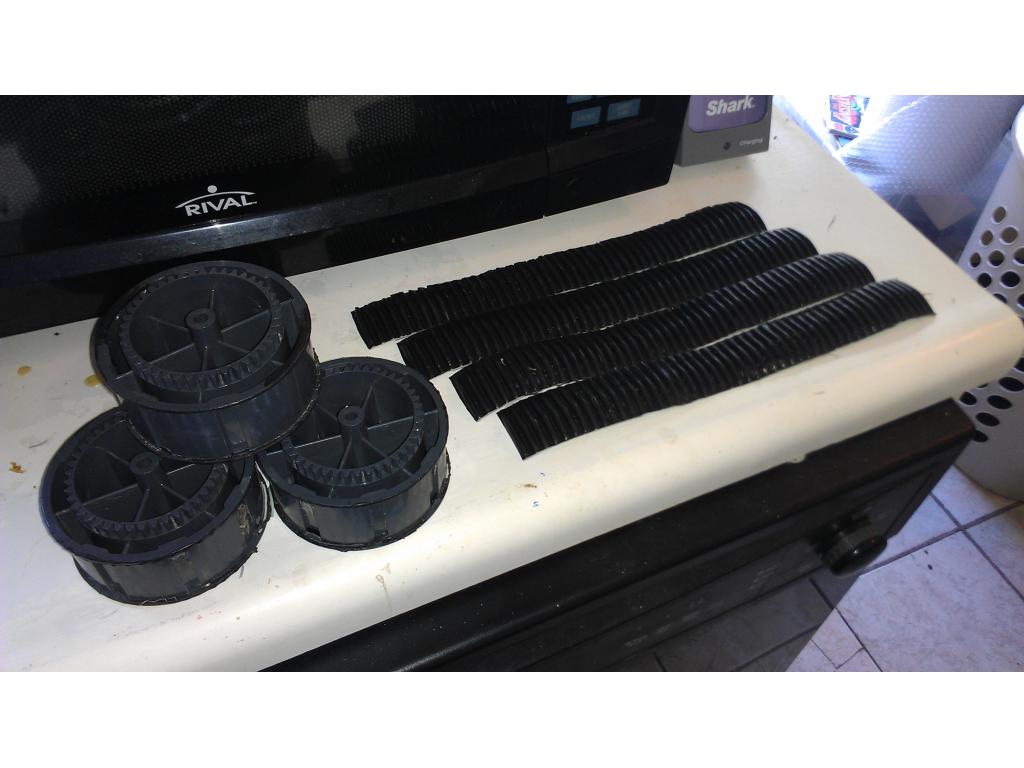
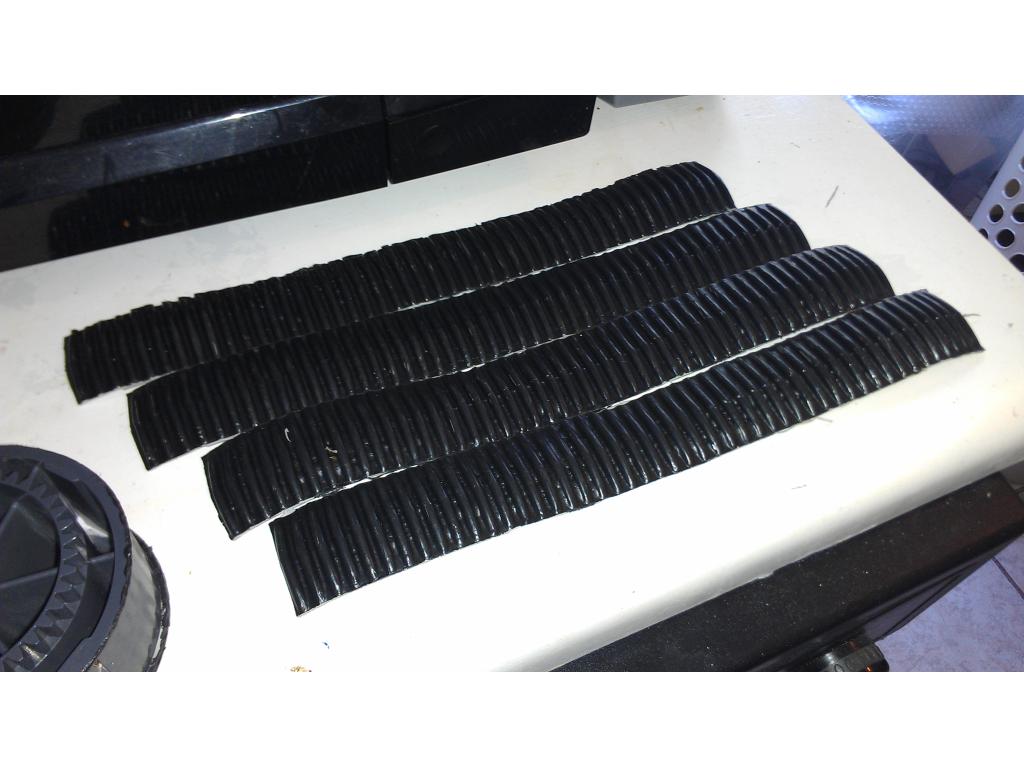
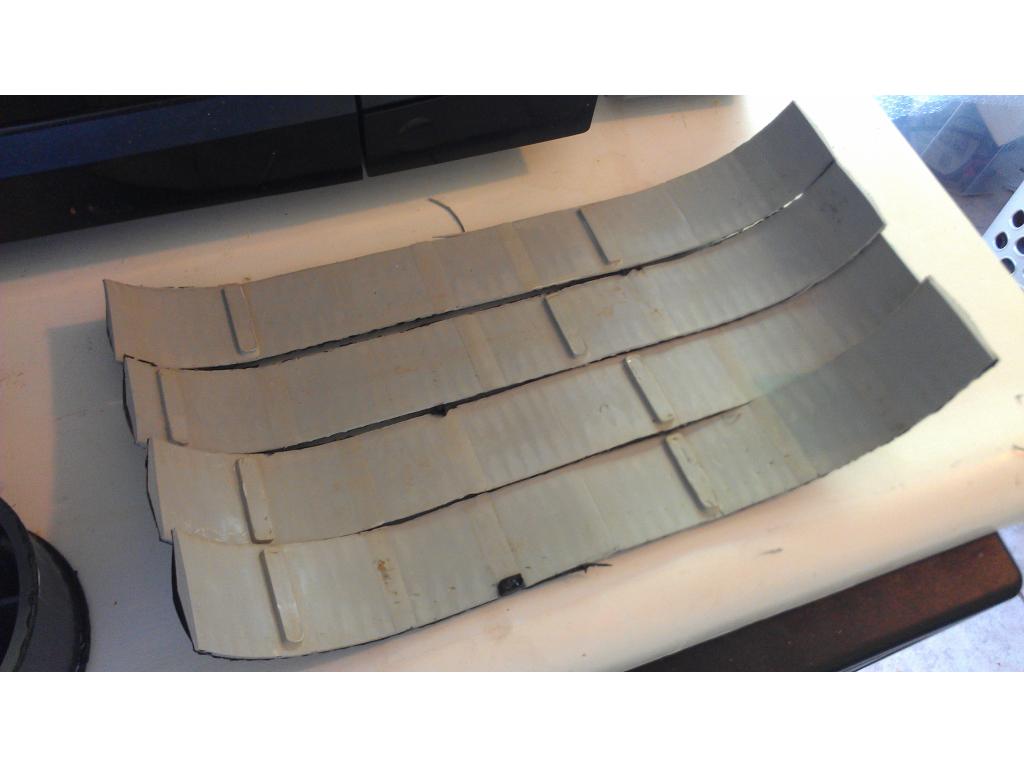
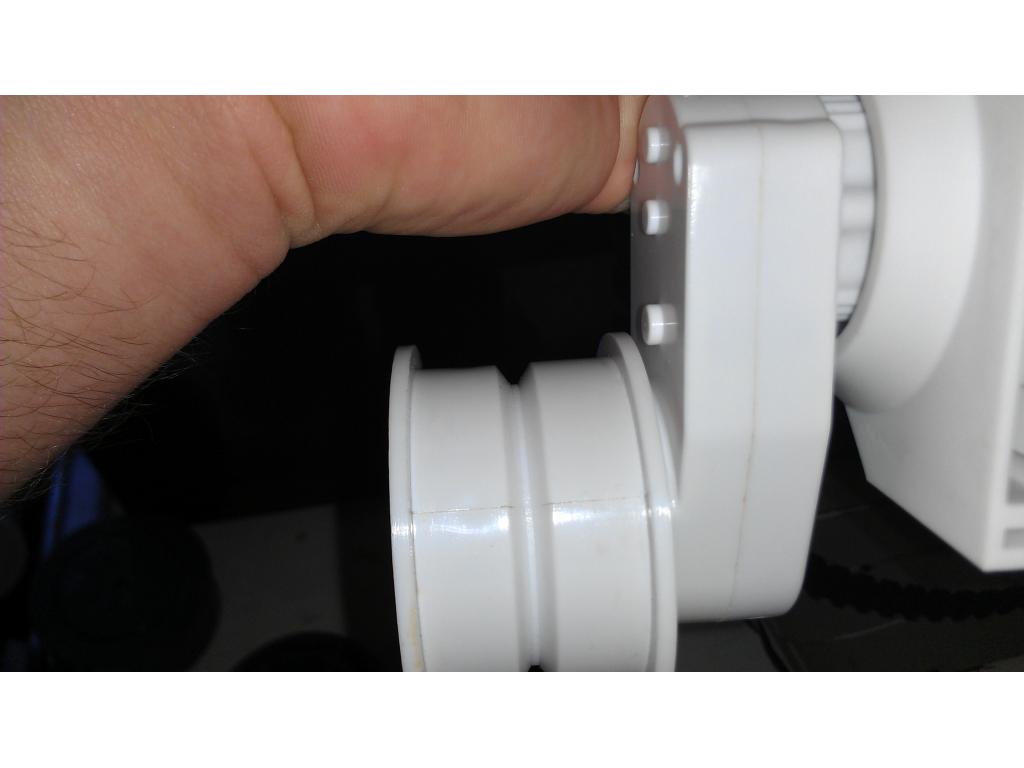
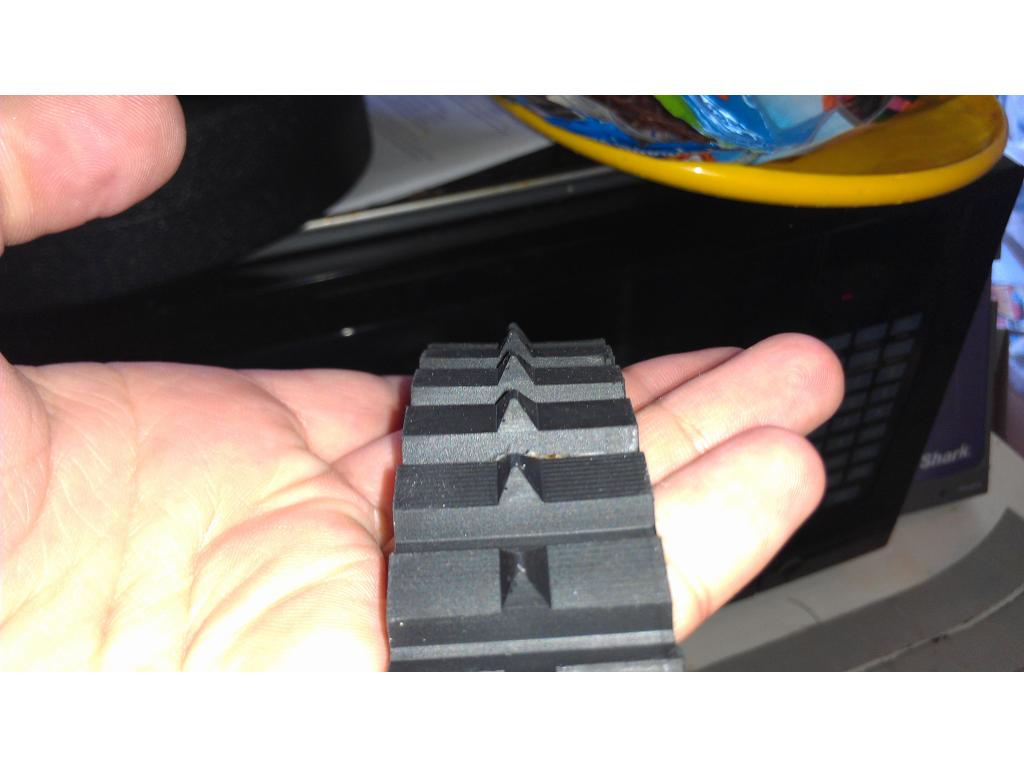
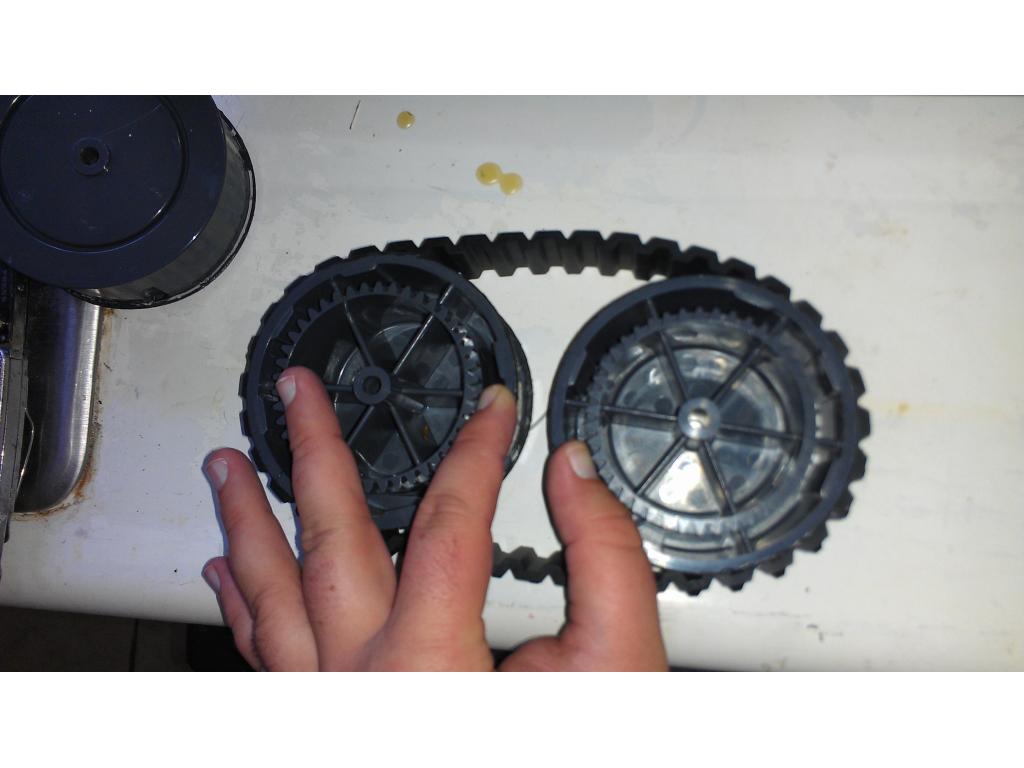
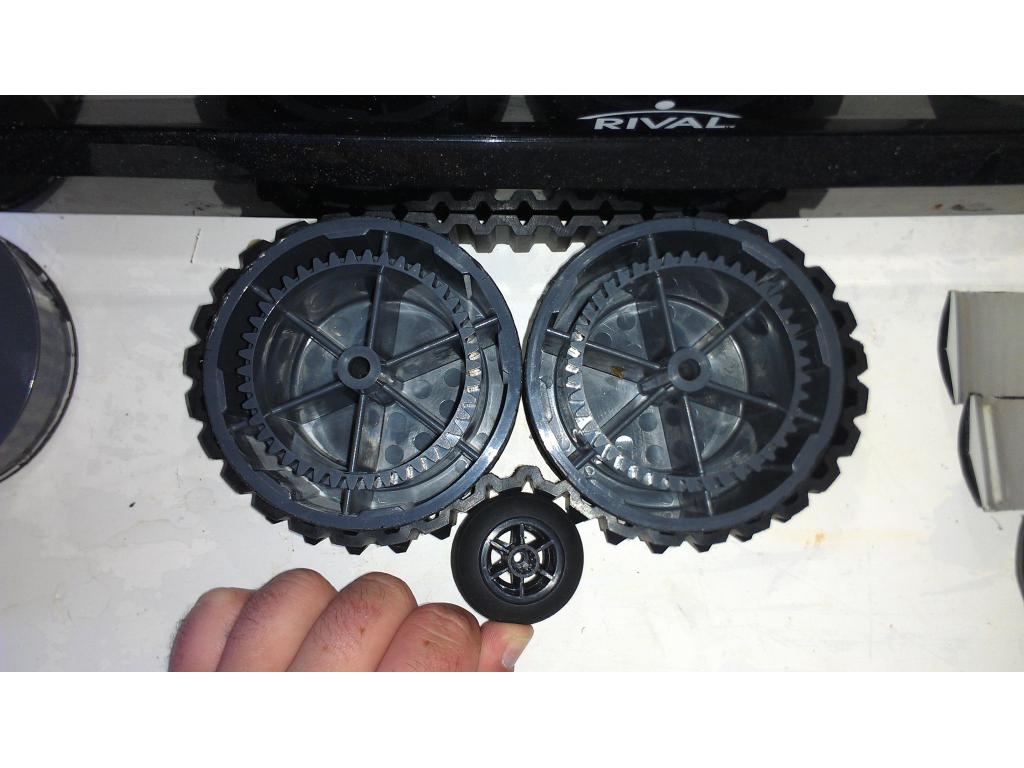
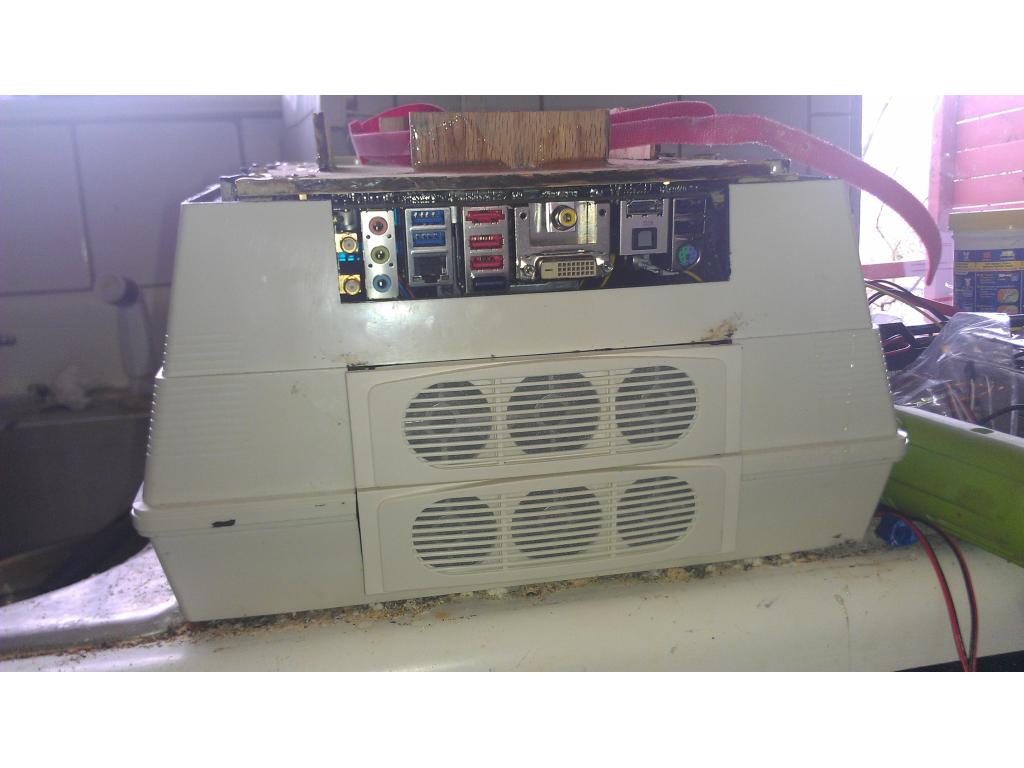
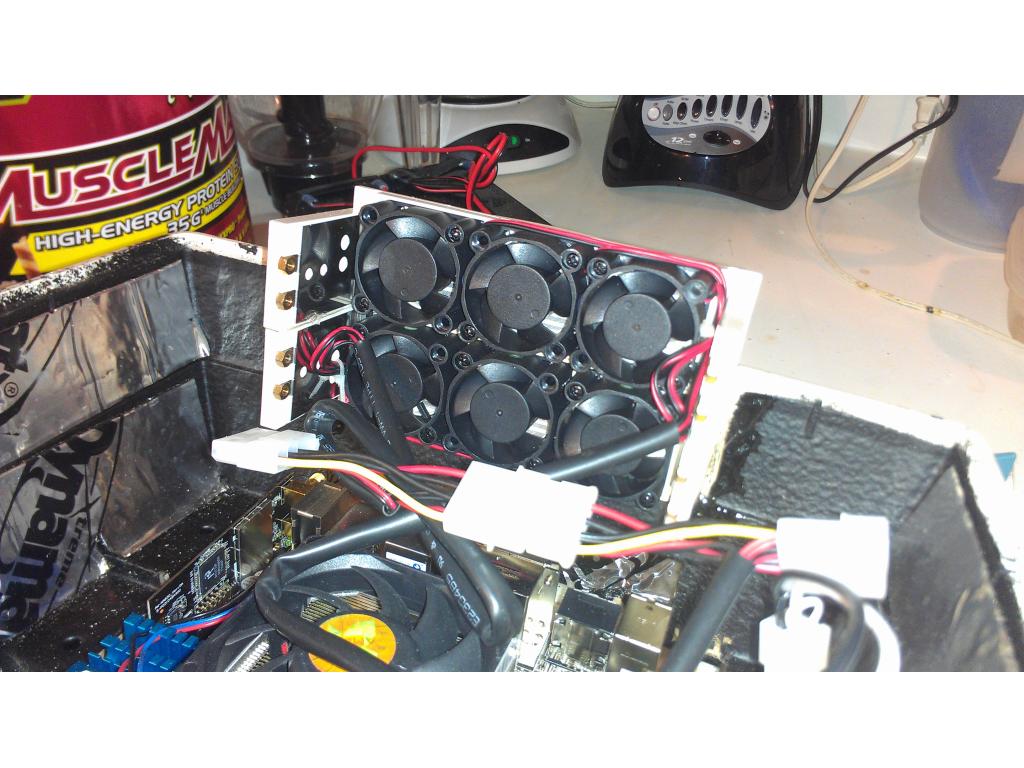
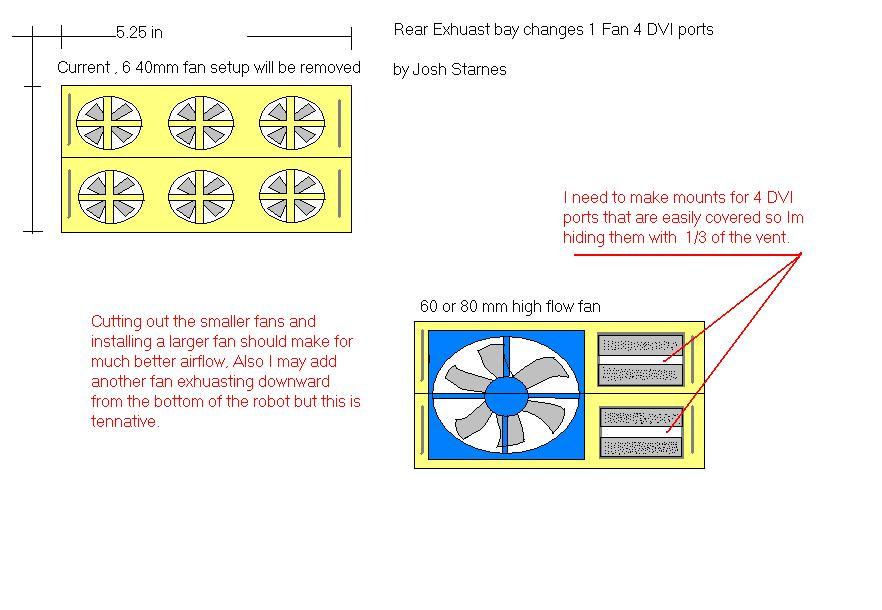
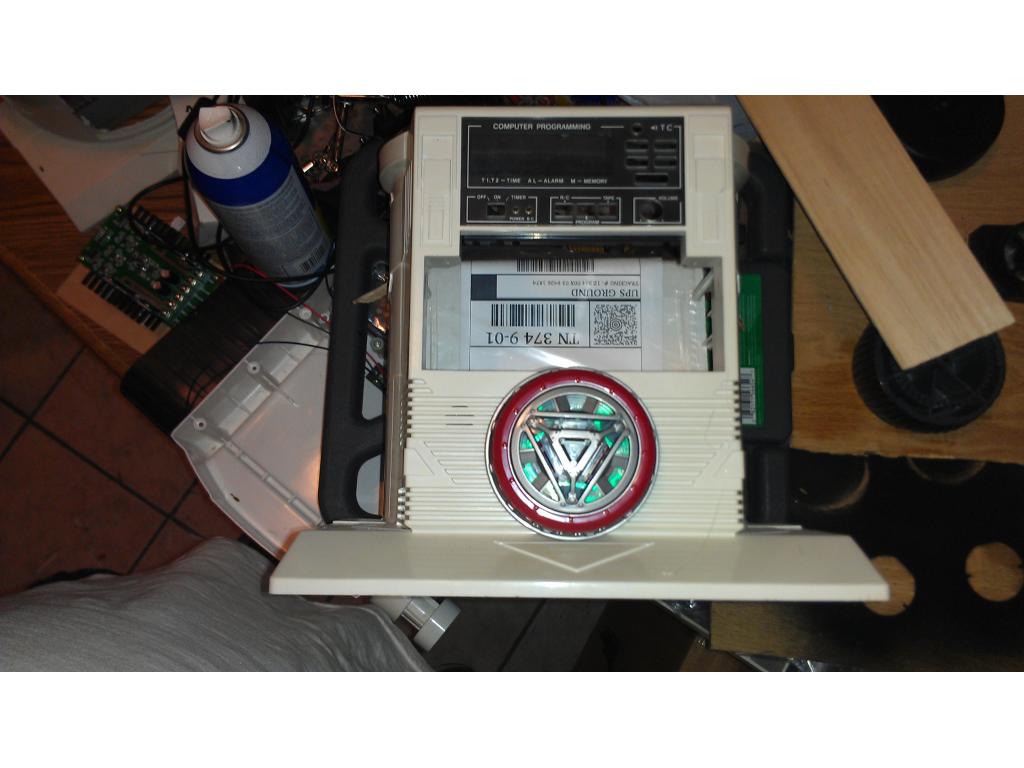
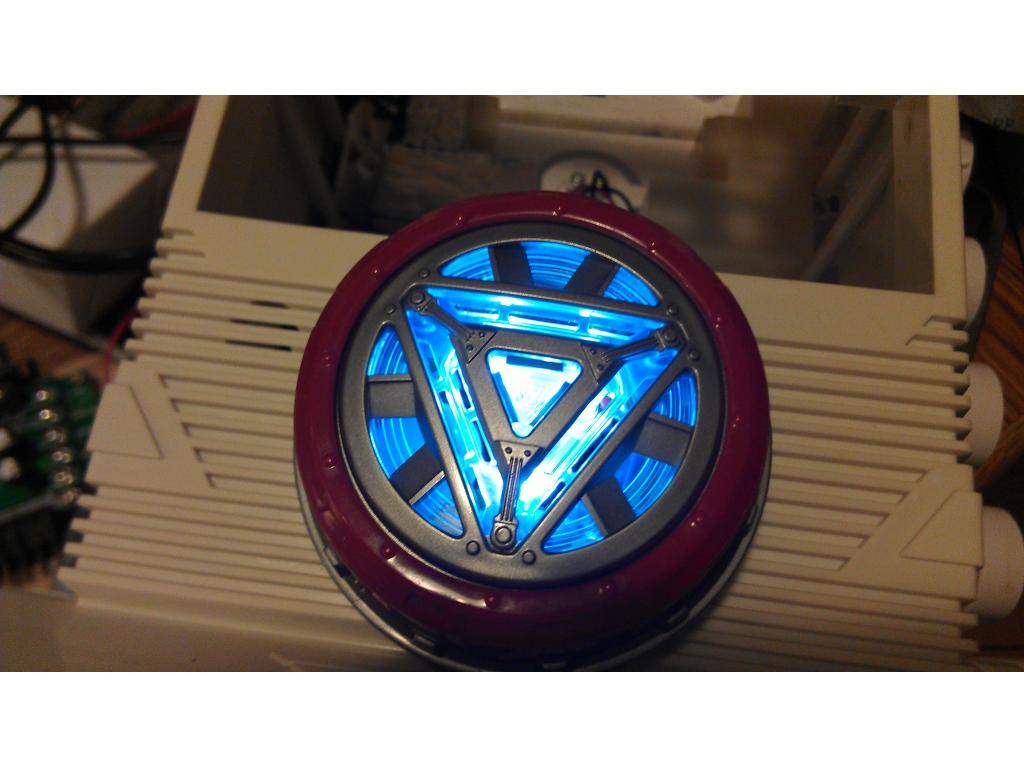
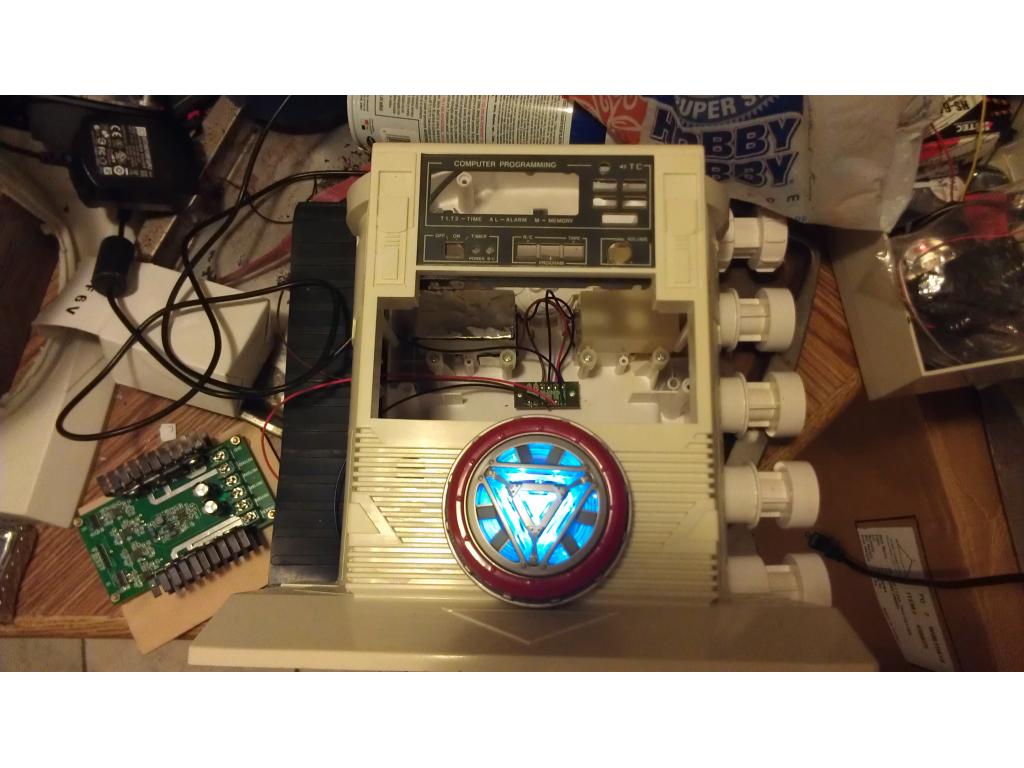
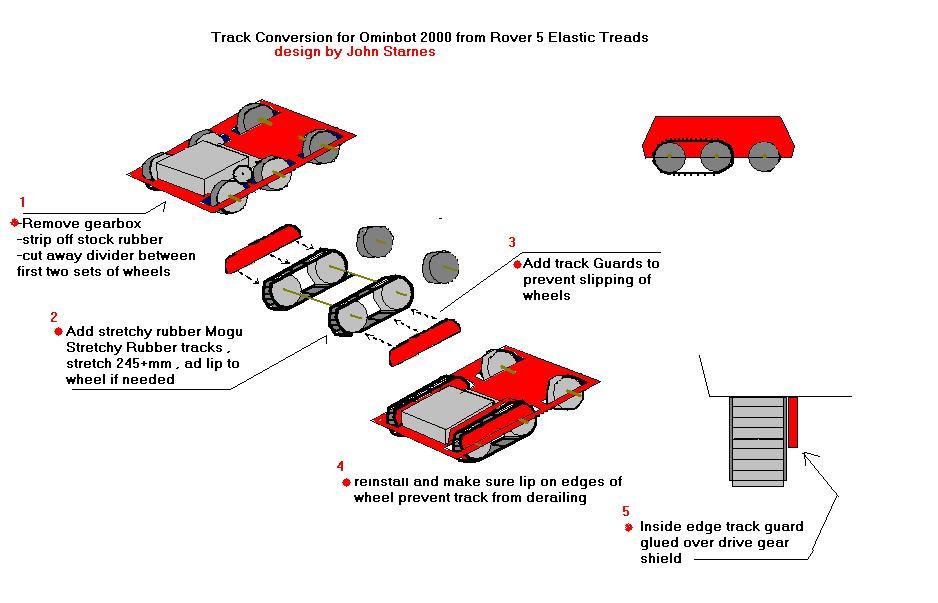
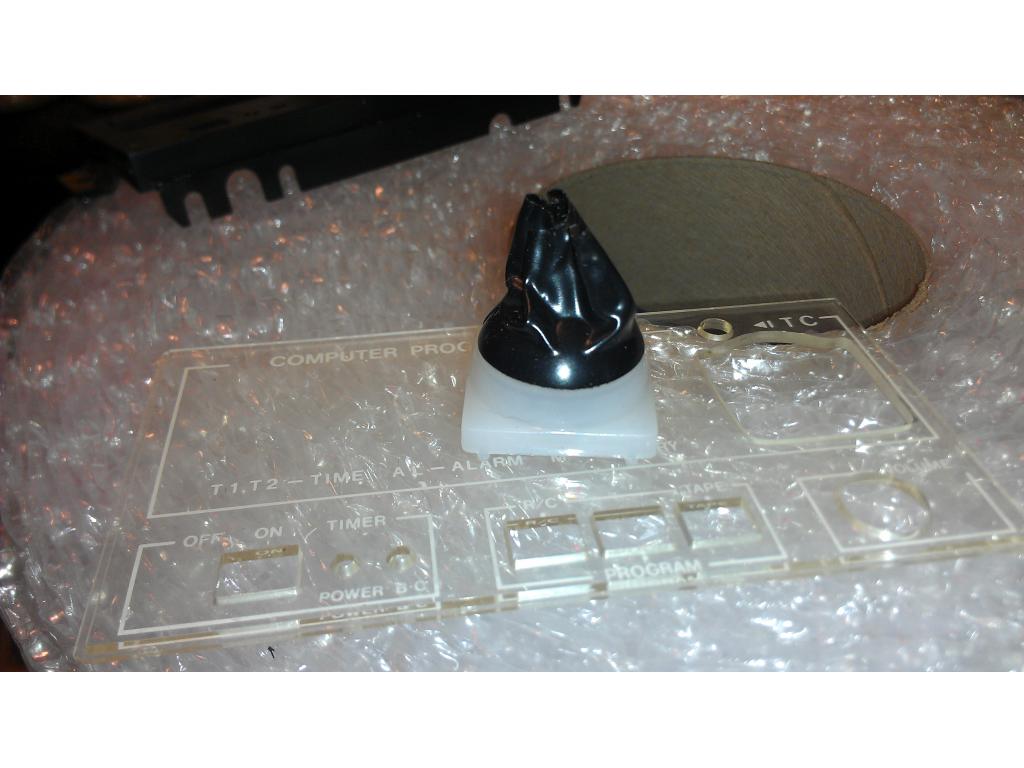
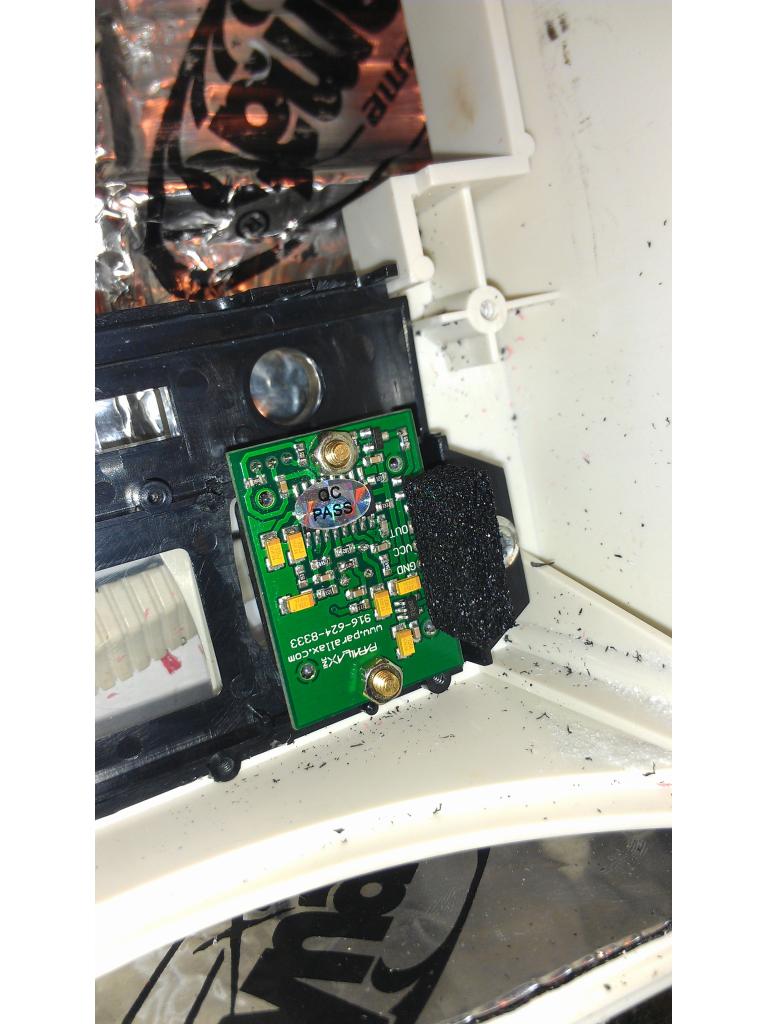
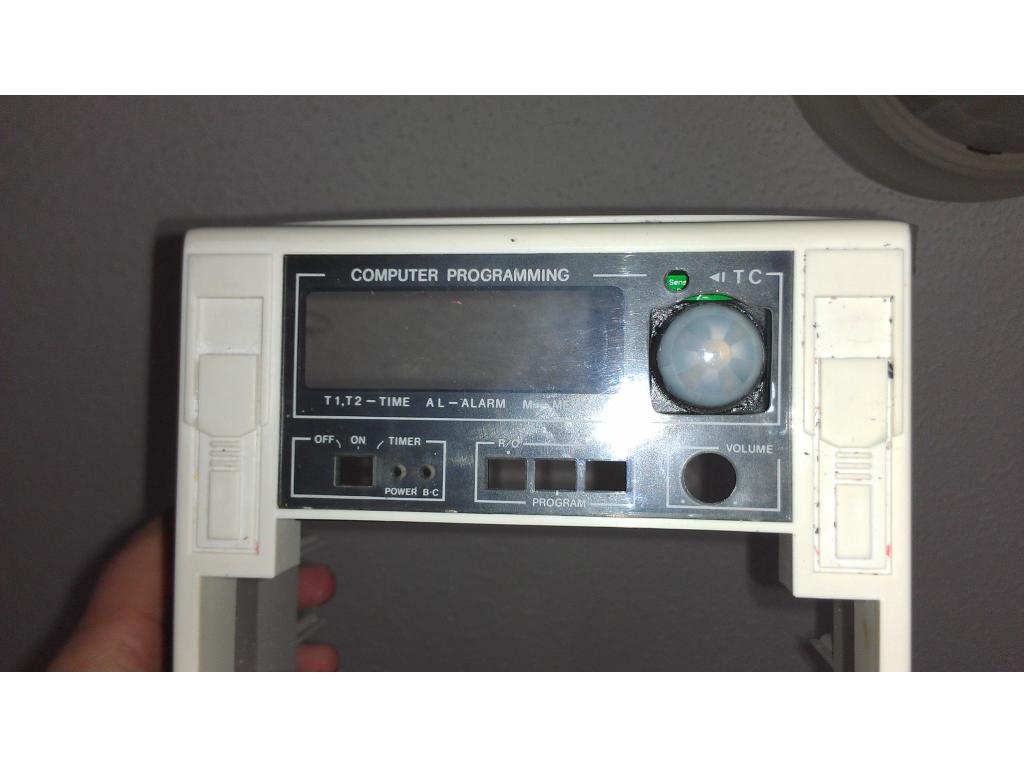
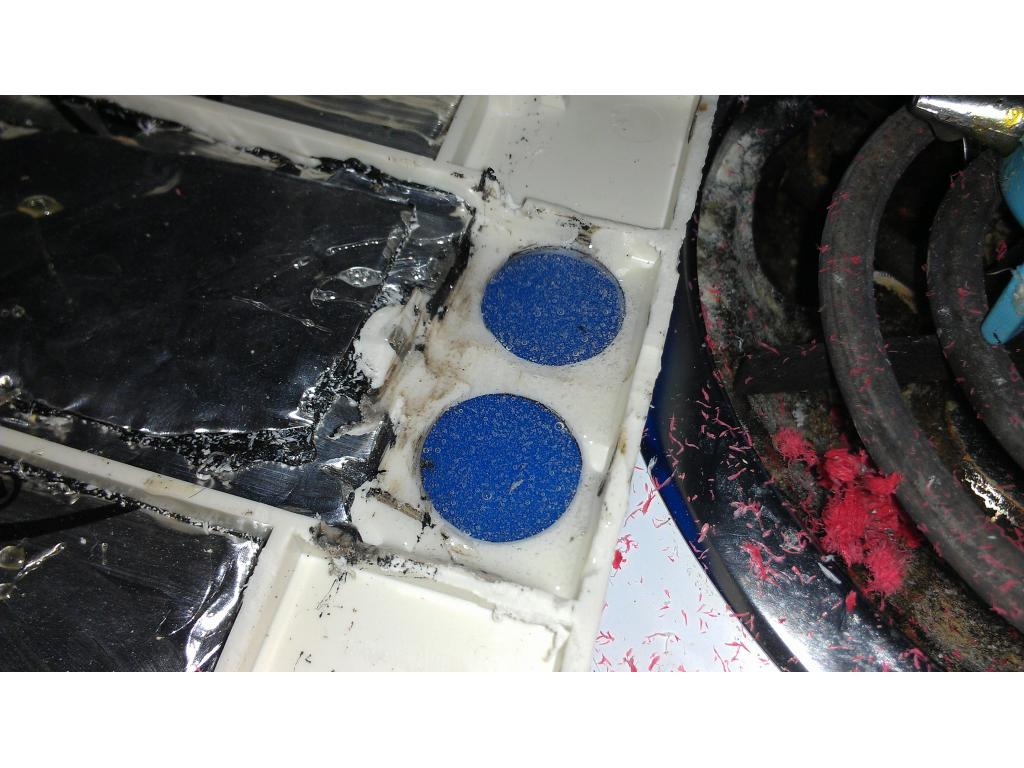
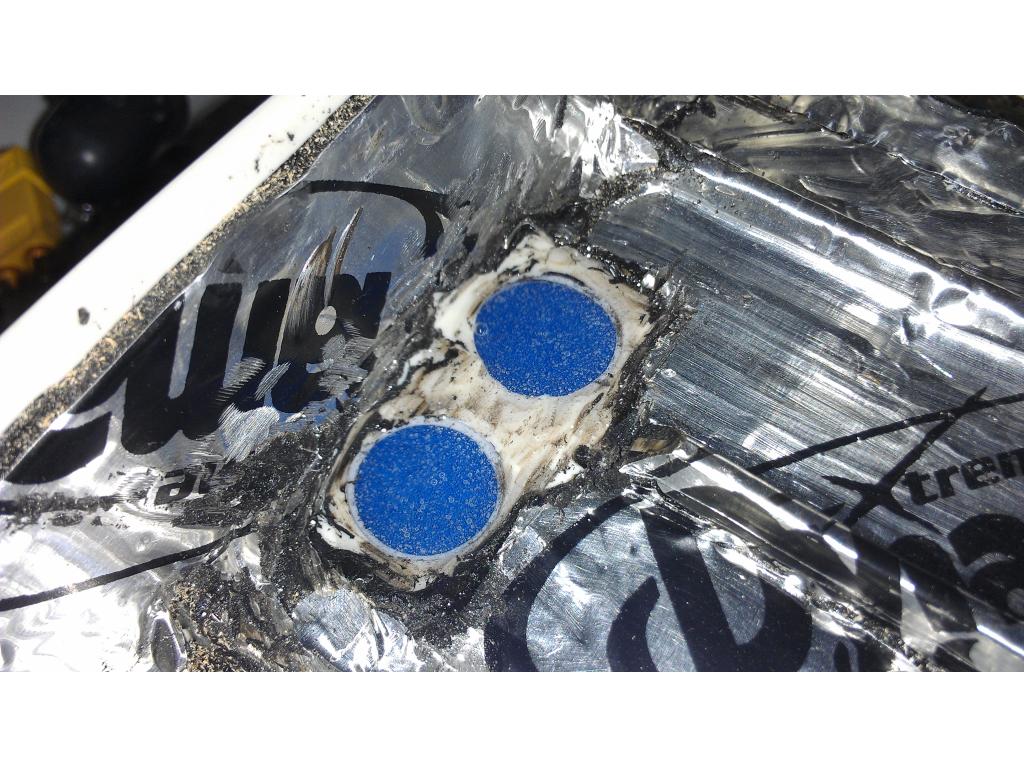
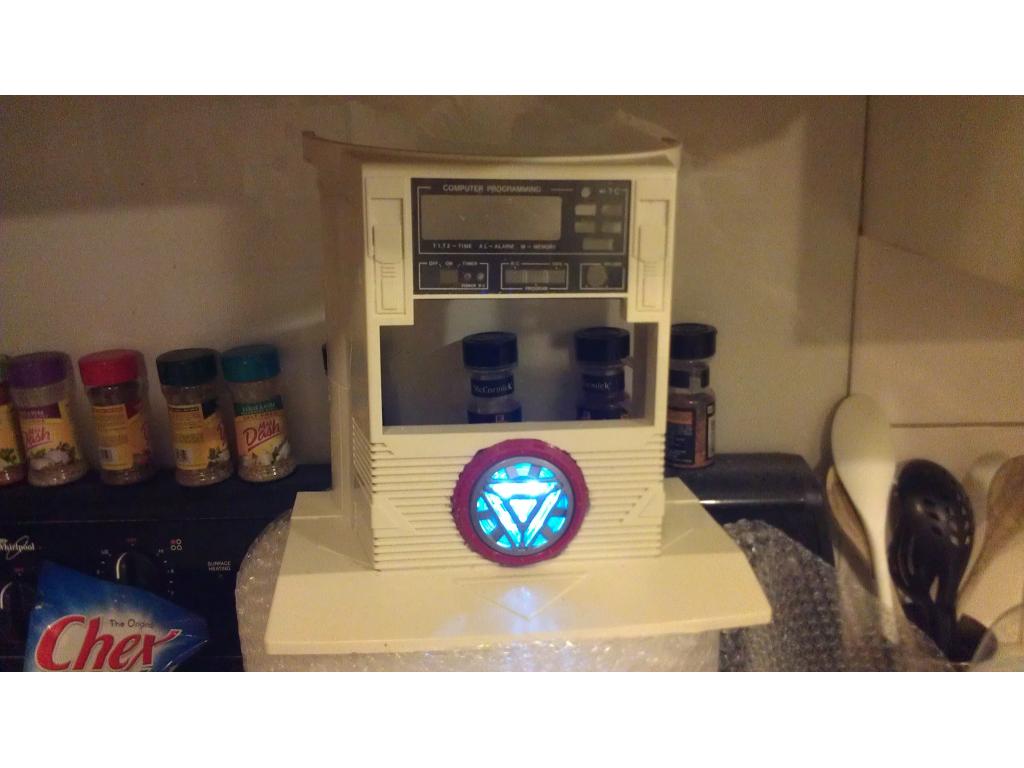
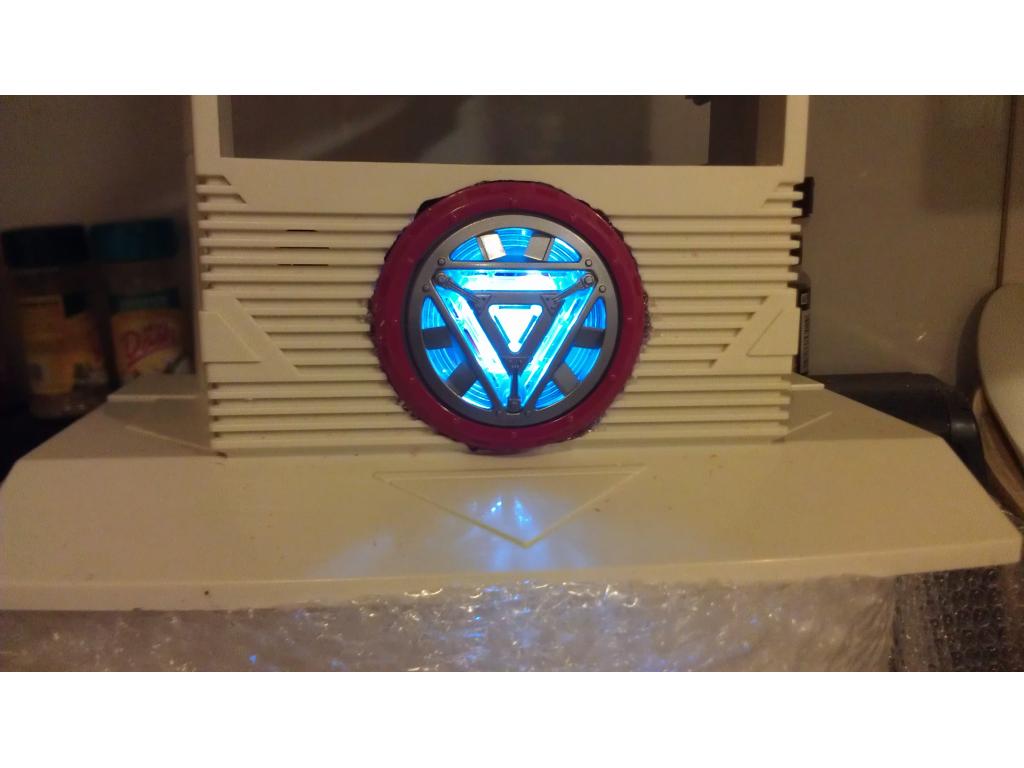
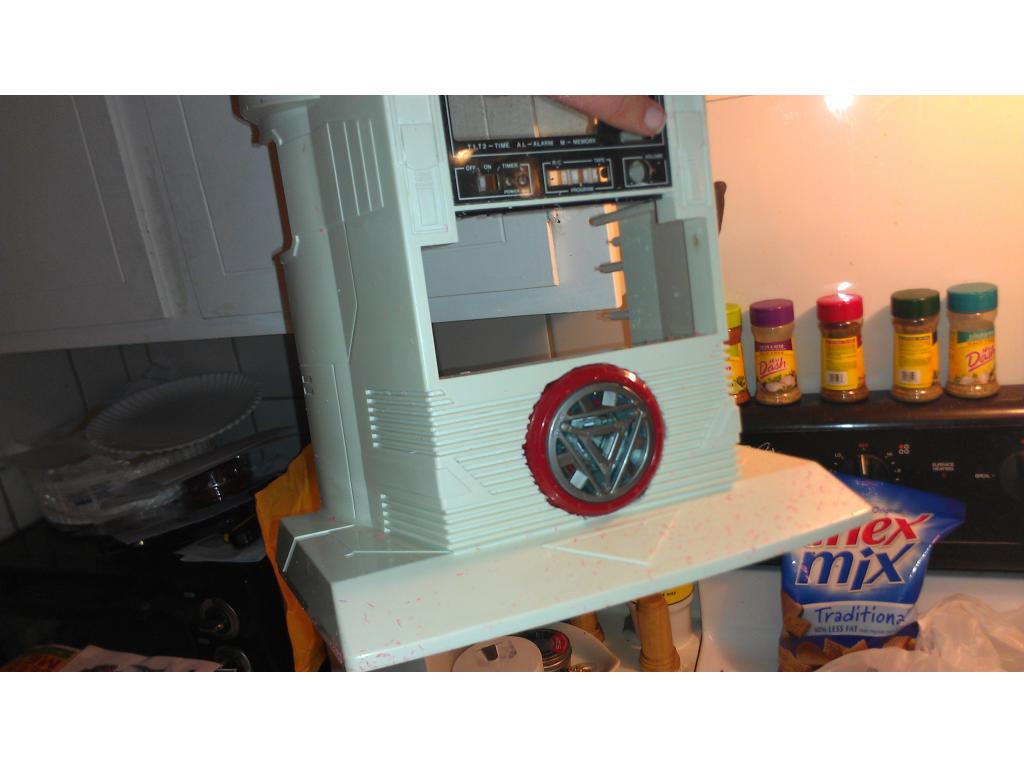
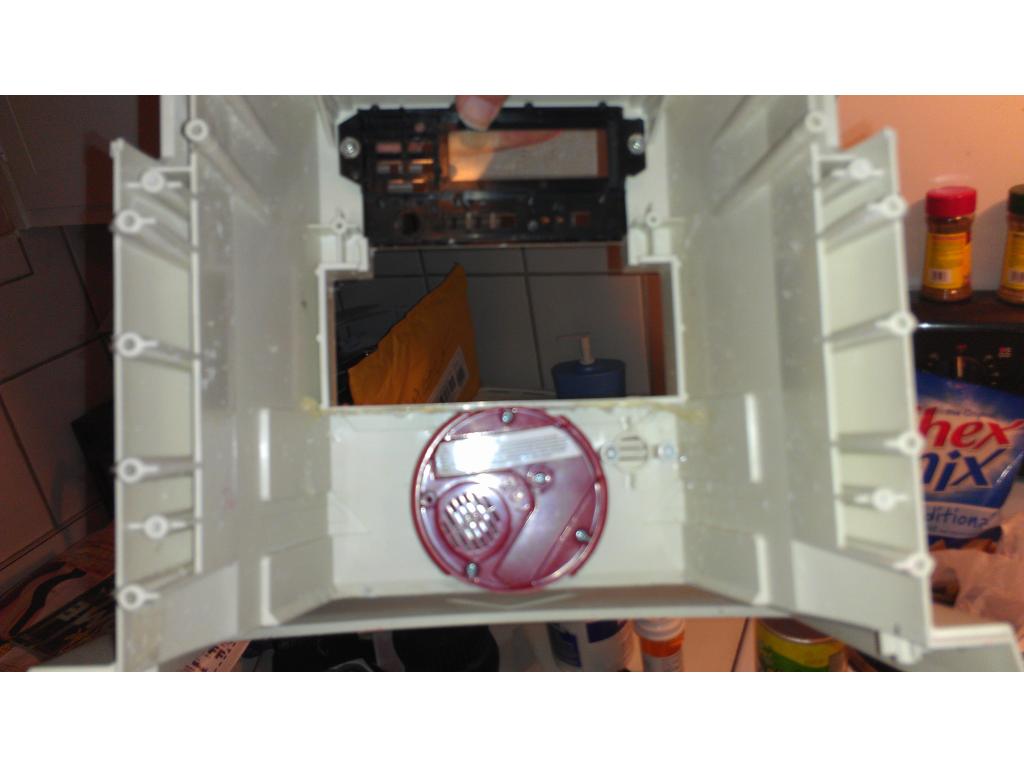
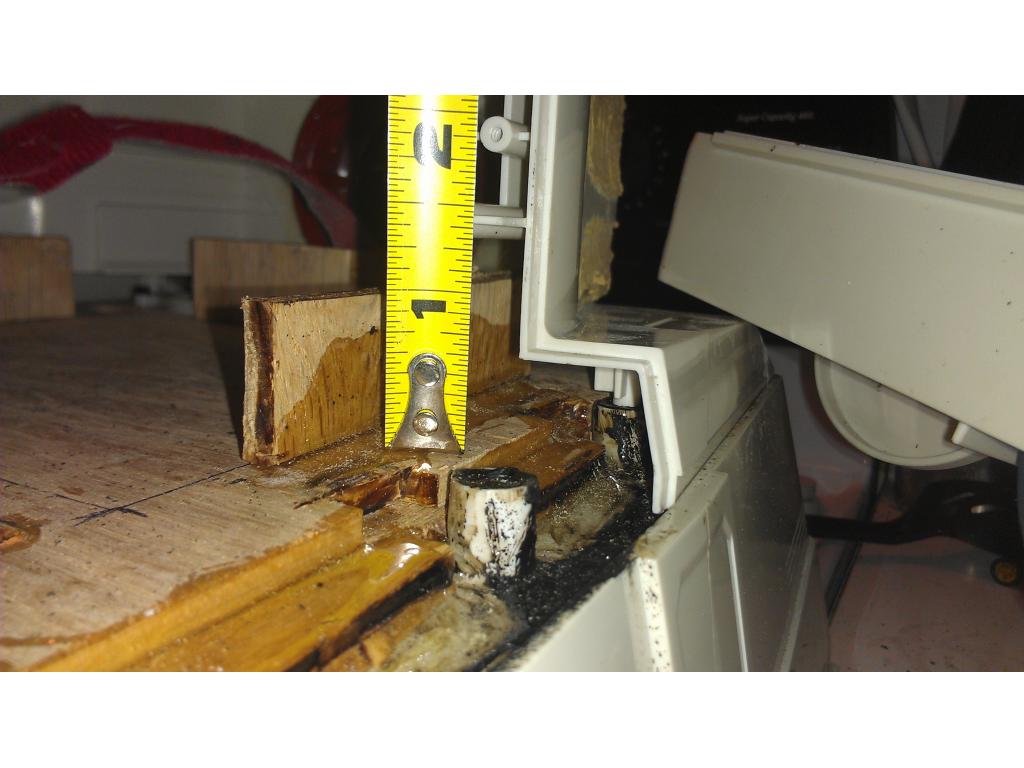
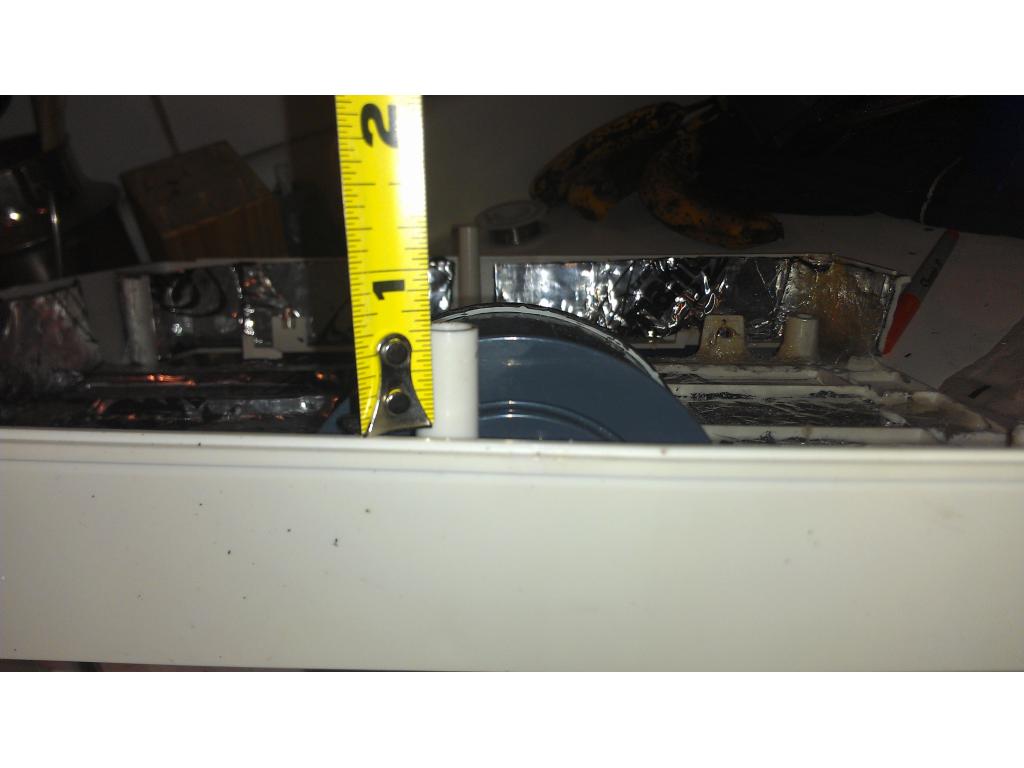
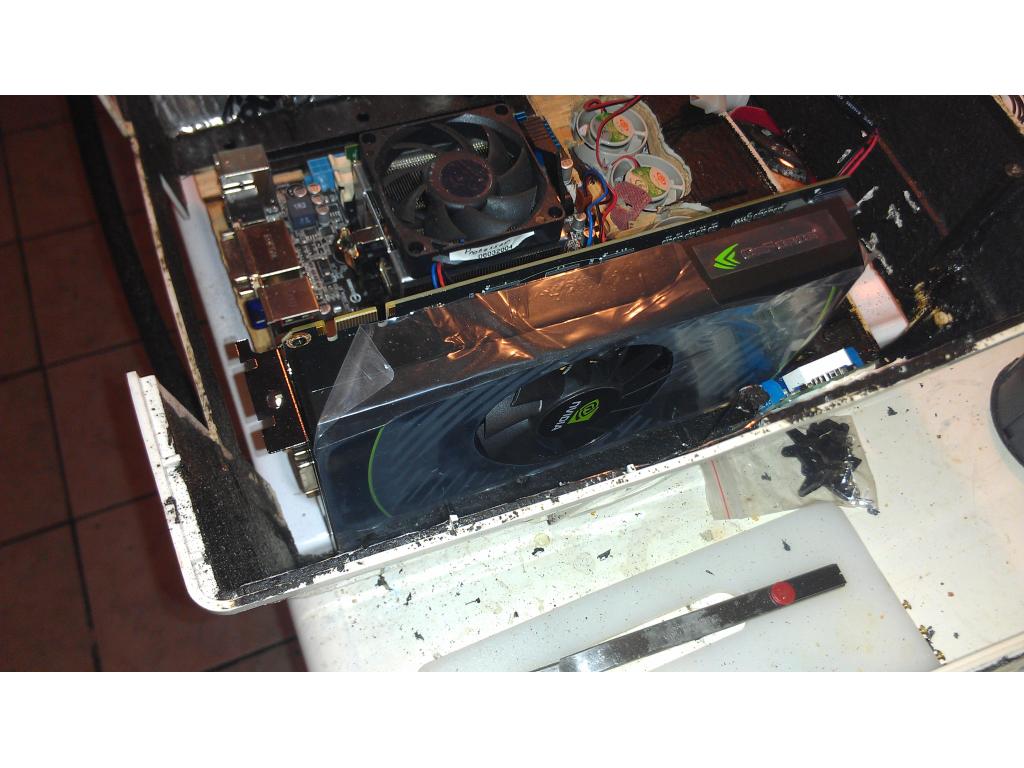
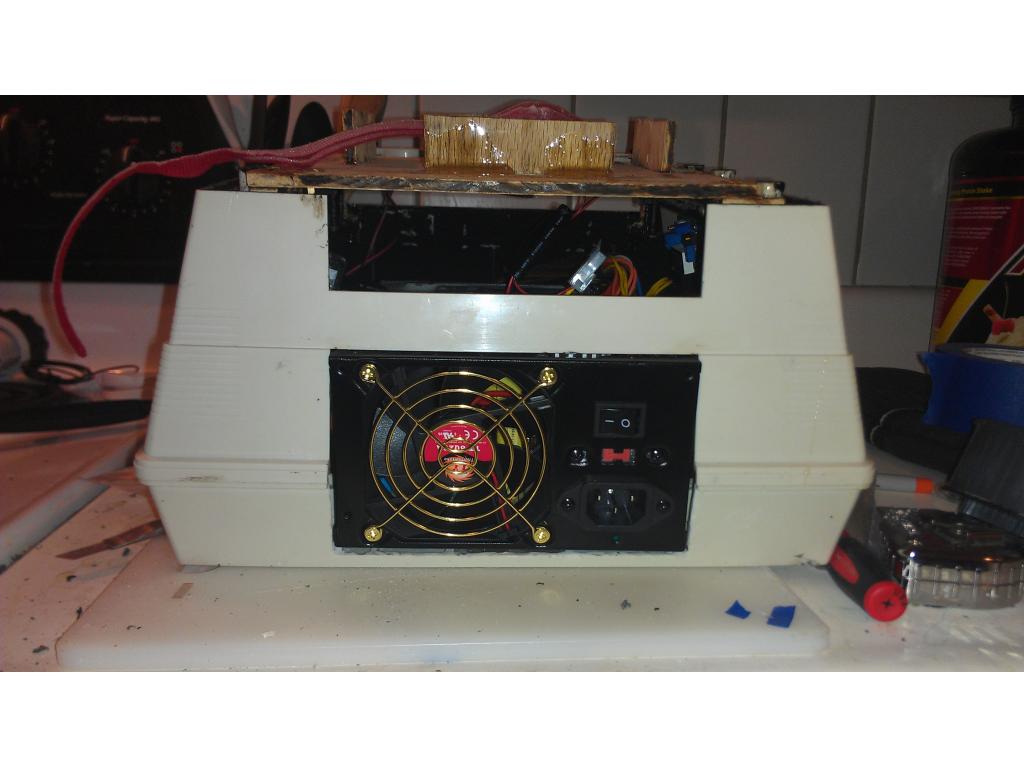
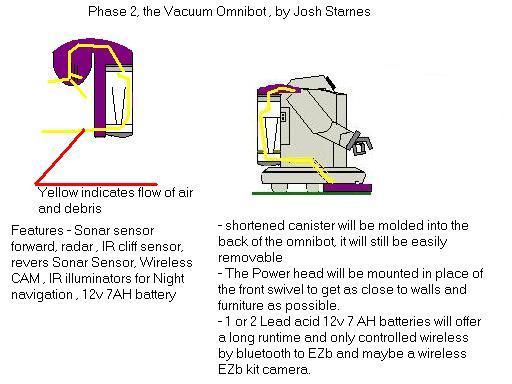
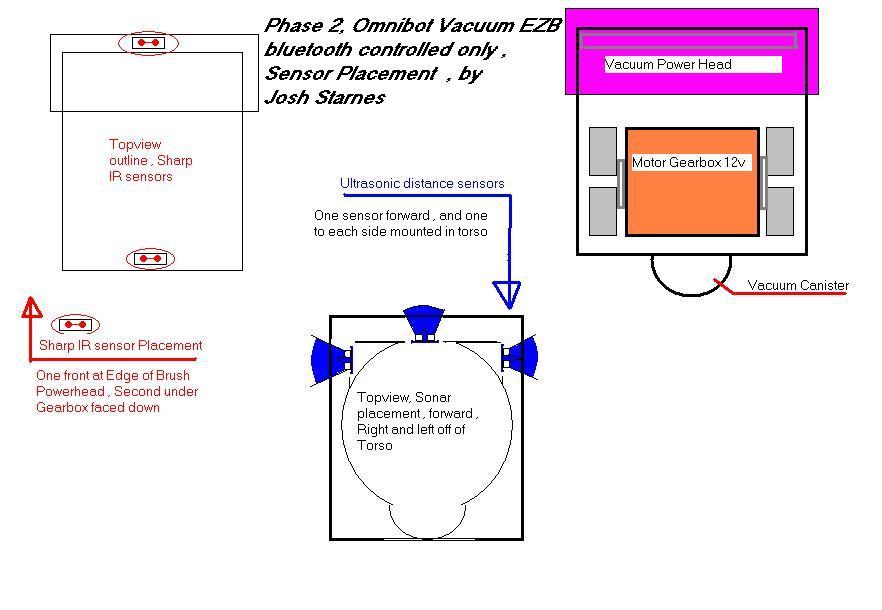
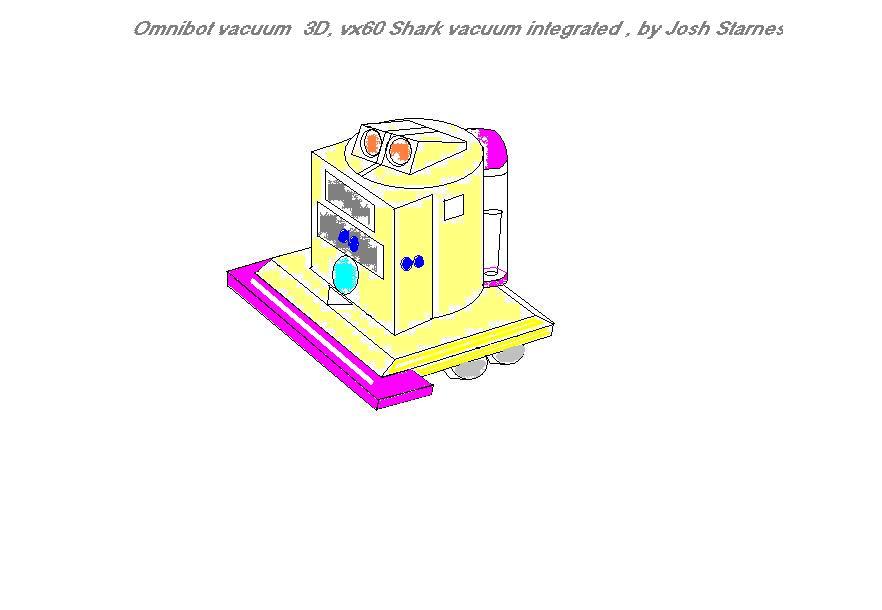
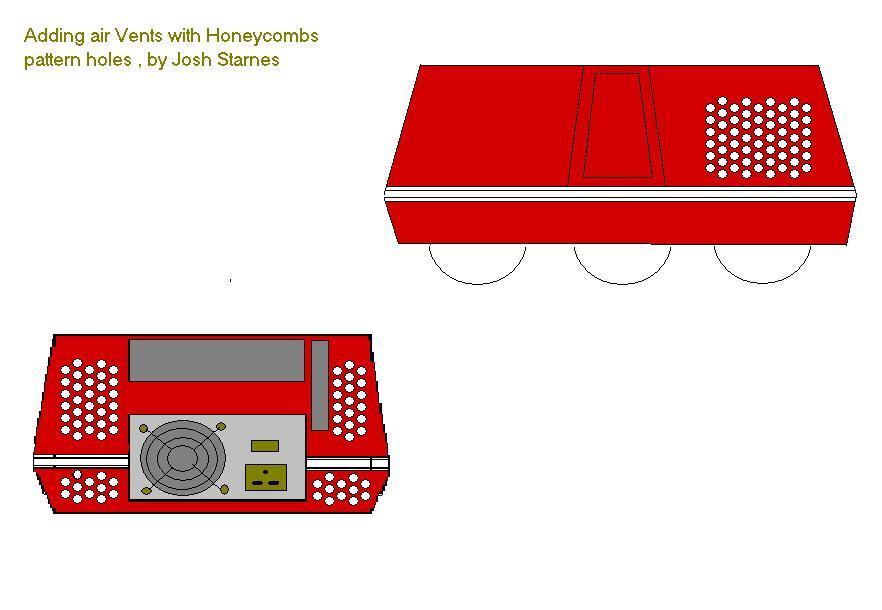
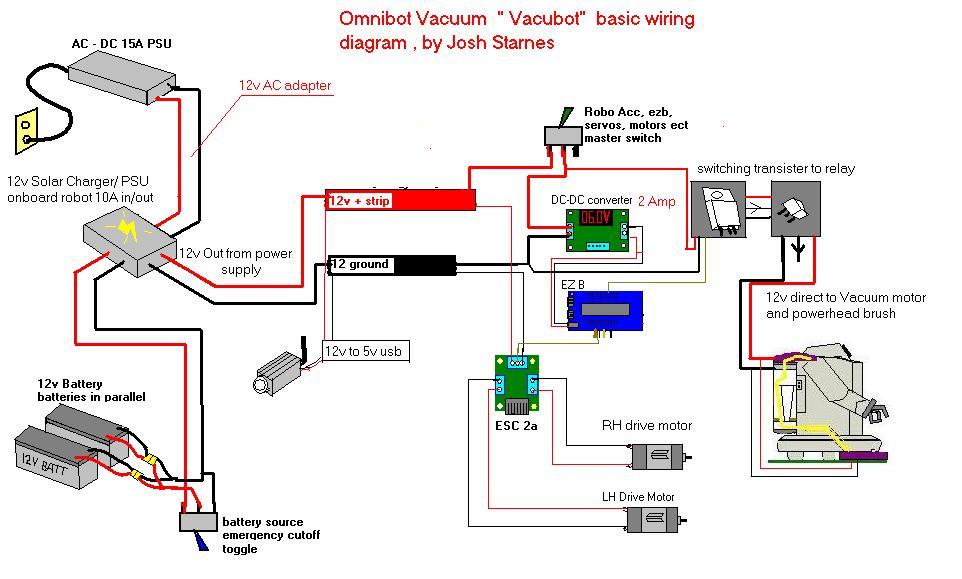
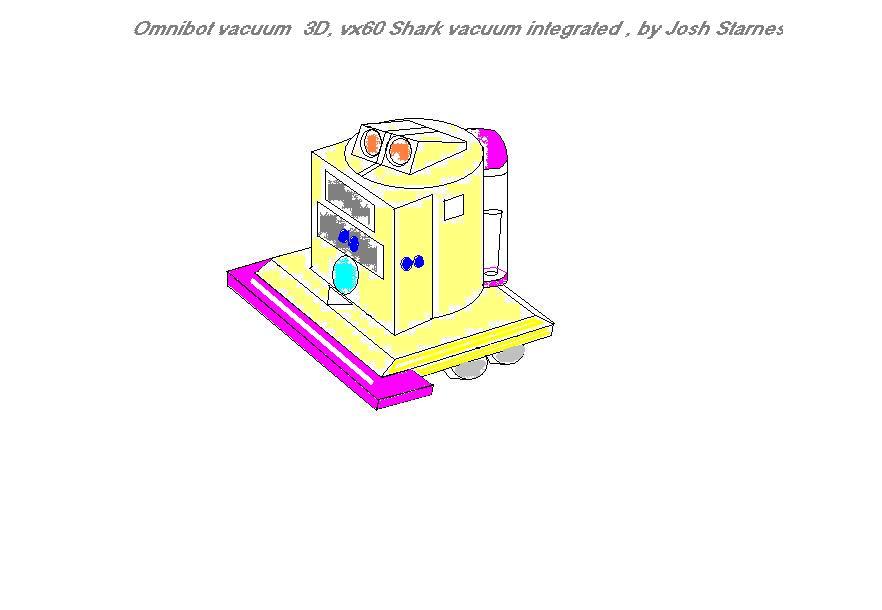
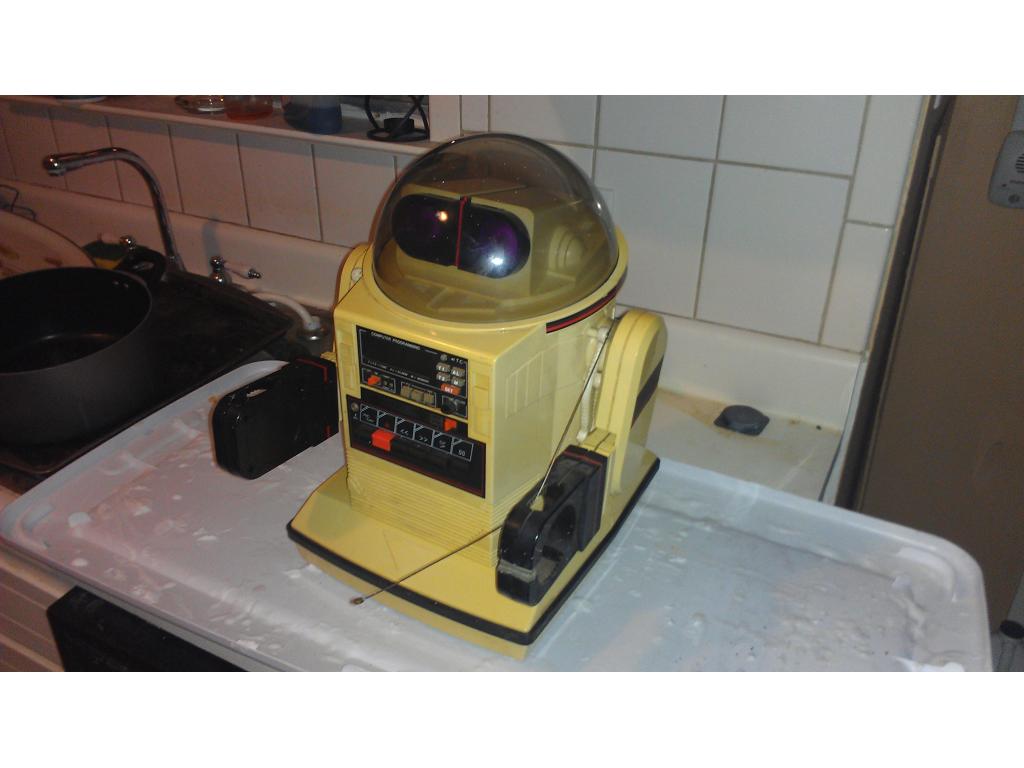
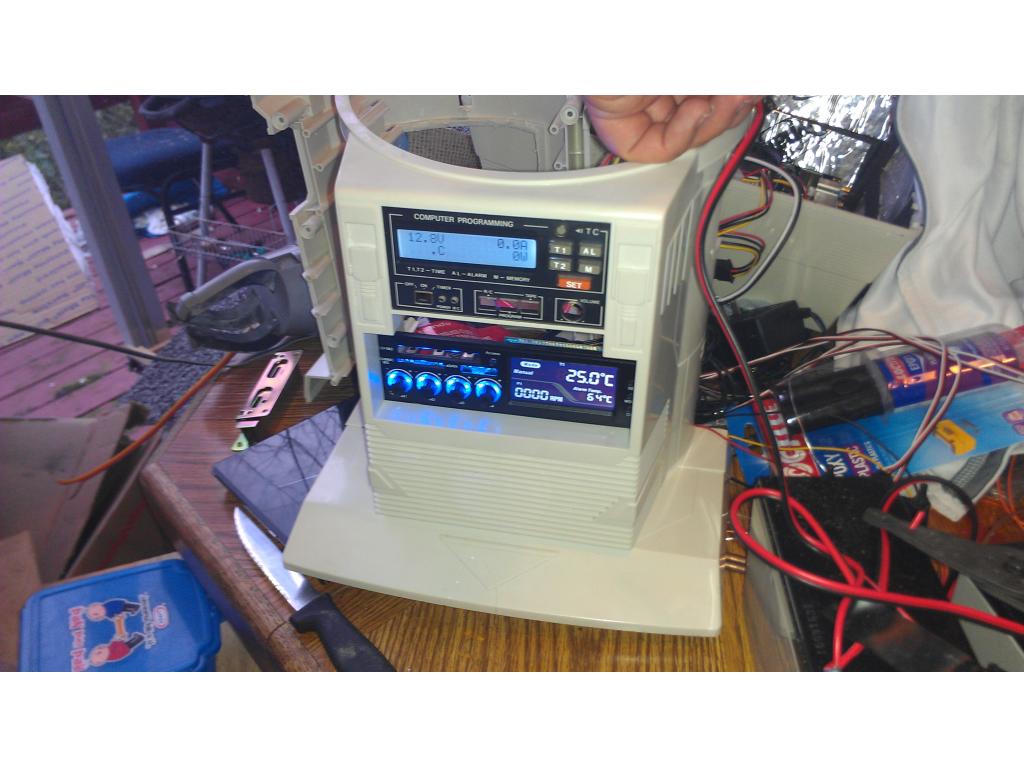
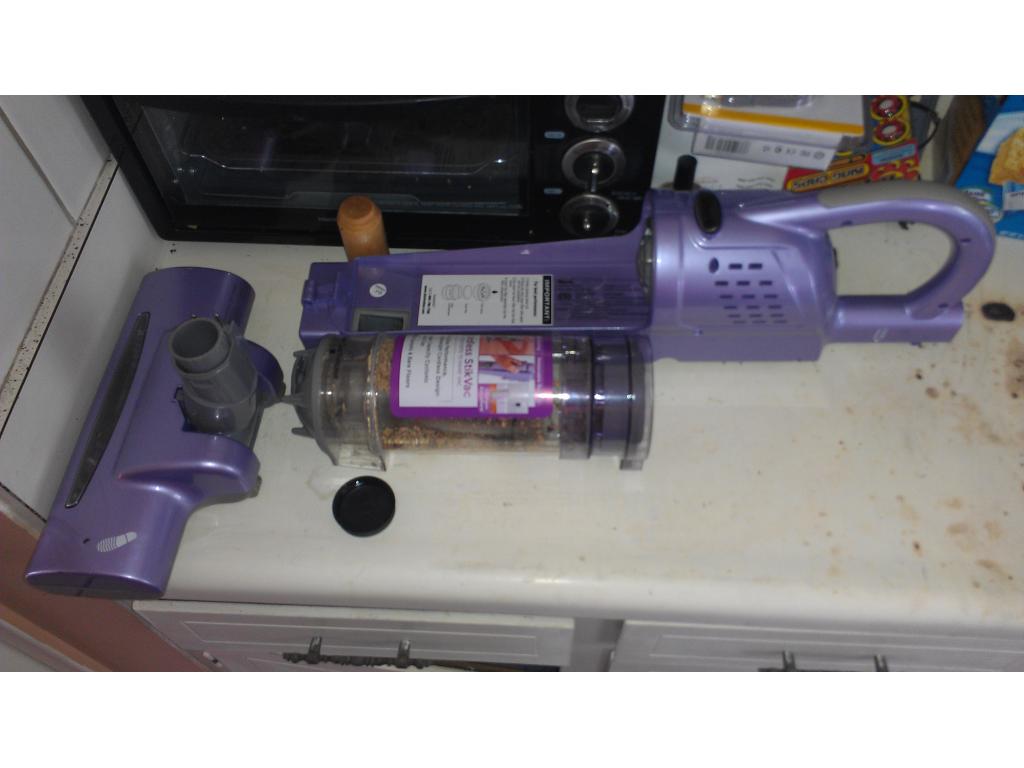
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.

By jstarne1
— Last update

Discover more robots
Morbeious's Dev Servo Bot
Build a simple Dev Kit hexapod with 3D-printed parts, camera and sonar options; parts list: body, servos, extension...
Bhouston's New Eye Mechanism For Inmoov
I can’t access external sites. Please paste the webpage text or key content here and I’ll create the 150-character meta...
Ezang's Modified AIML BOT
Conversational AIML robot that answers questions with servo-driven eyes and mouth, DF Robot Hexa Base Rotate head,...

Or you could have EZB in upper half and one in lower half. Then divide ports between upper torso things and lower torso things
That's a idea too , well see once he is back from paint lol
that whats best part i see on EZB easy to make codes
Well hopefully Jarvis will be at least 99% where you want it before paint. Im sure touch up paint wont look quite the same.
Touch up paint is the 8th deadly sin lol , yeah the goal is zero cuts on any visible parts once painted.
Of course eventually you will want to make changes at some point. I love seeing the progress on the beast! Geez I really should get to work on mine.
will need to check on your been awhile,so far looking good glickclik
Thank you. I will post more in a day or two. Ive got a day off coming. :/