cE9s4PsOgeBQIORwjd5!~~60_1-634818020230156250.jpg)
Lupuc4g~~60_35-634706297915000000.jpg)
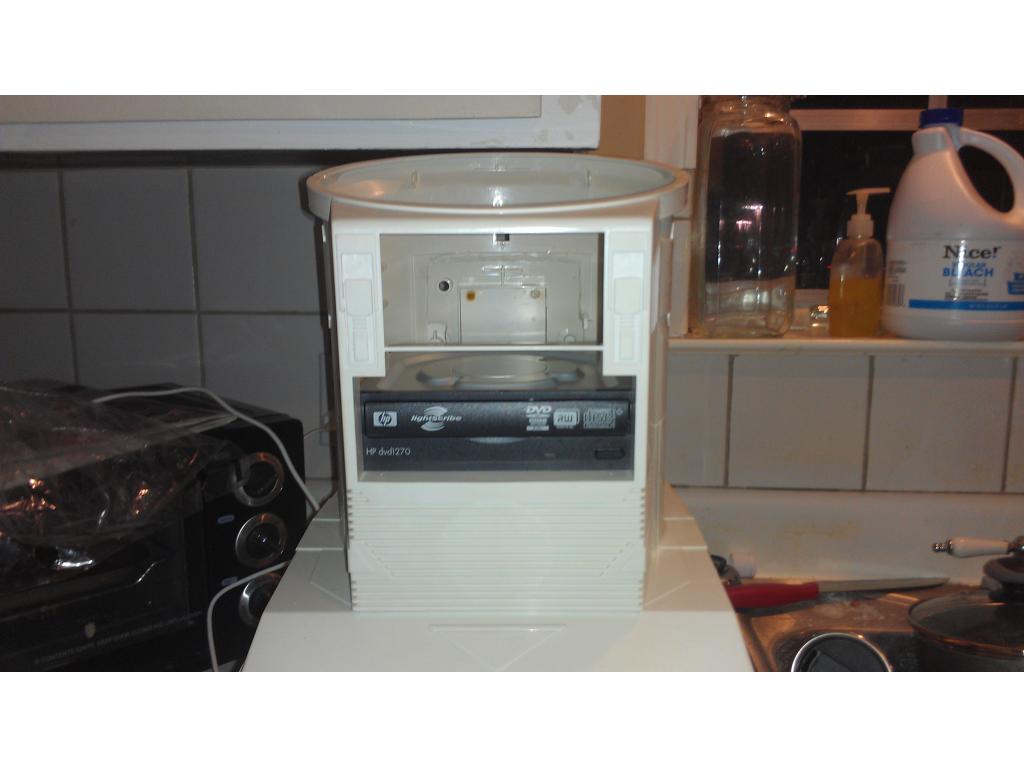
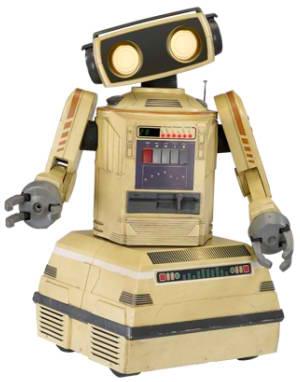
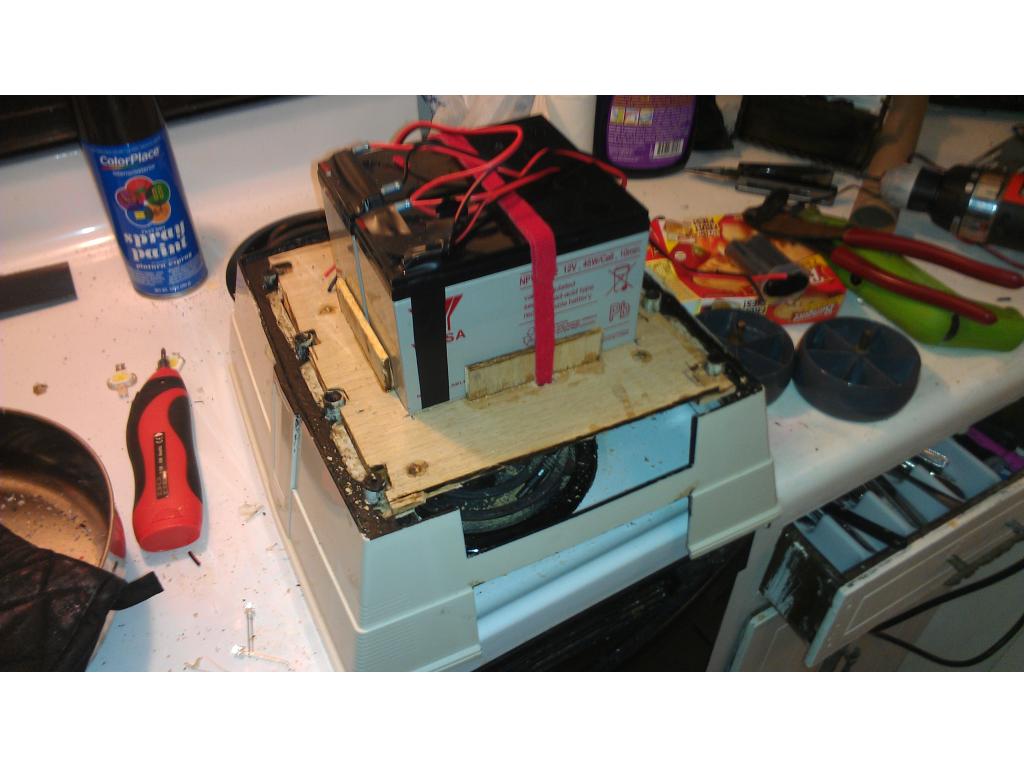
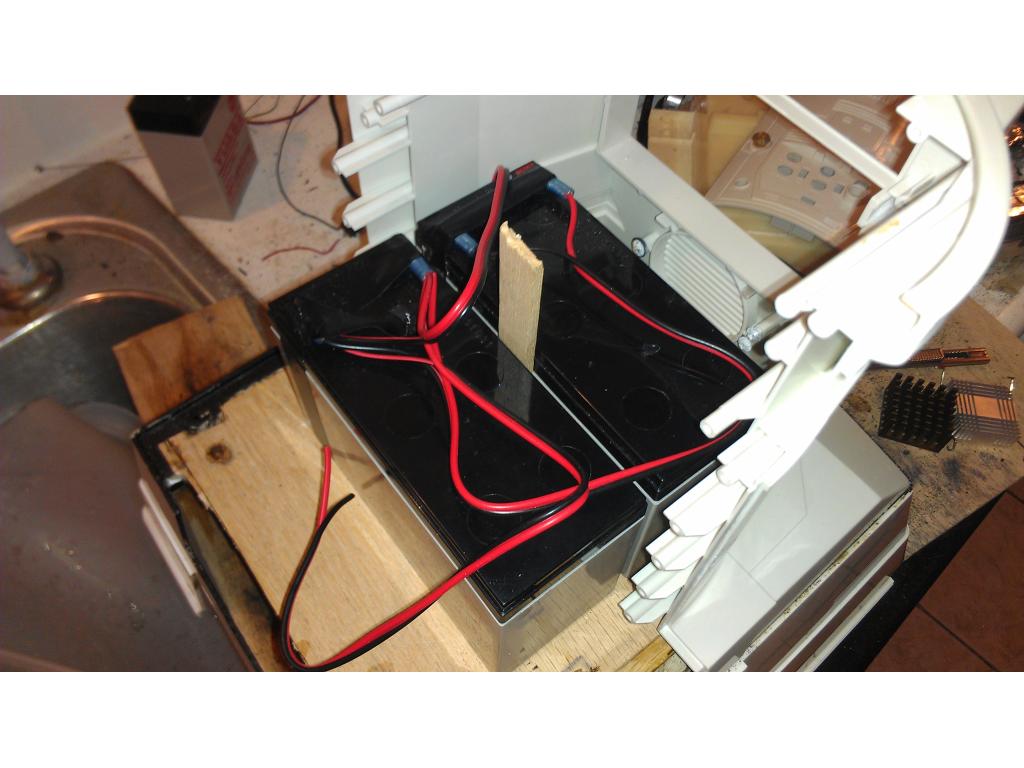
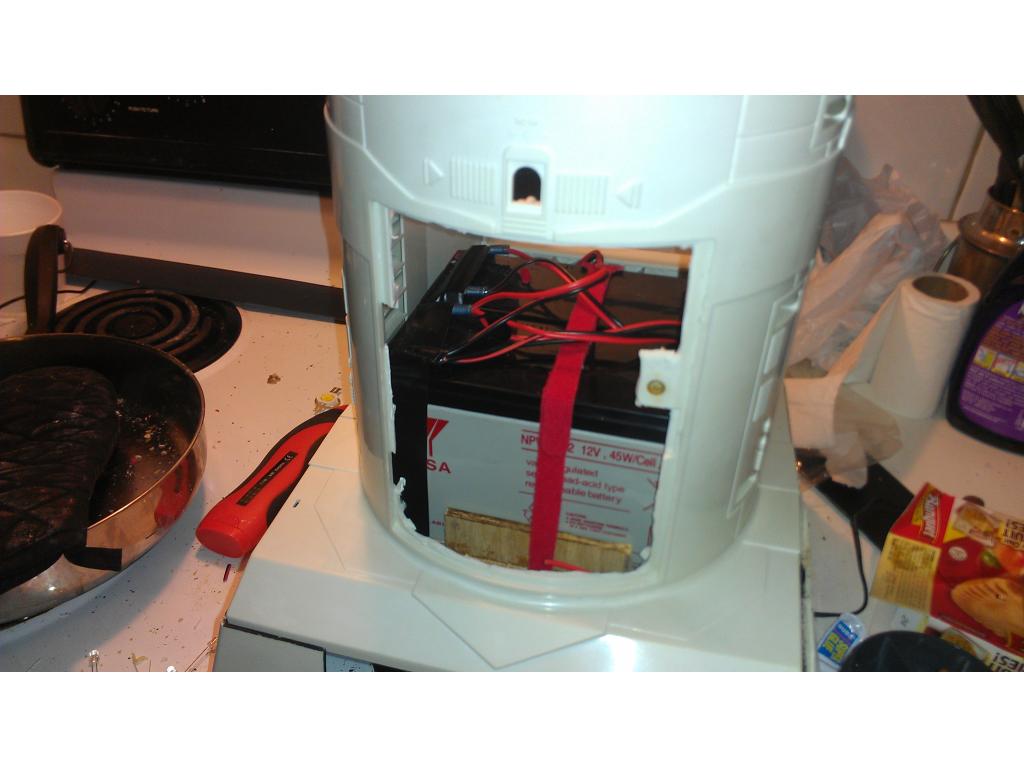
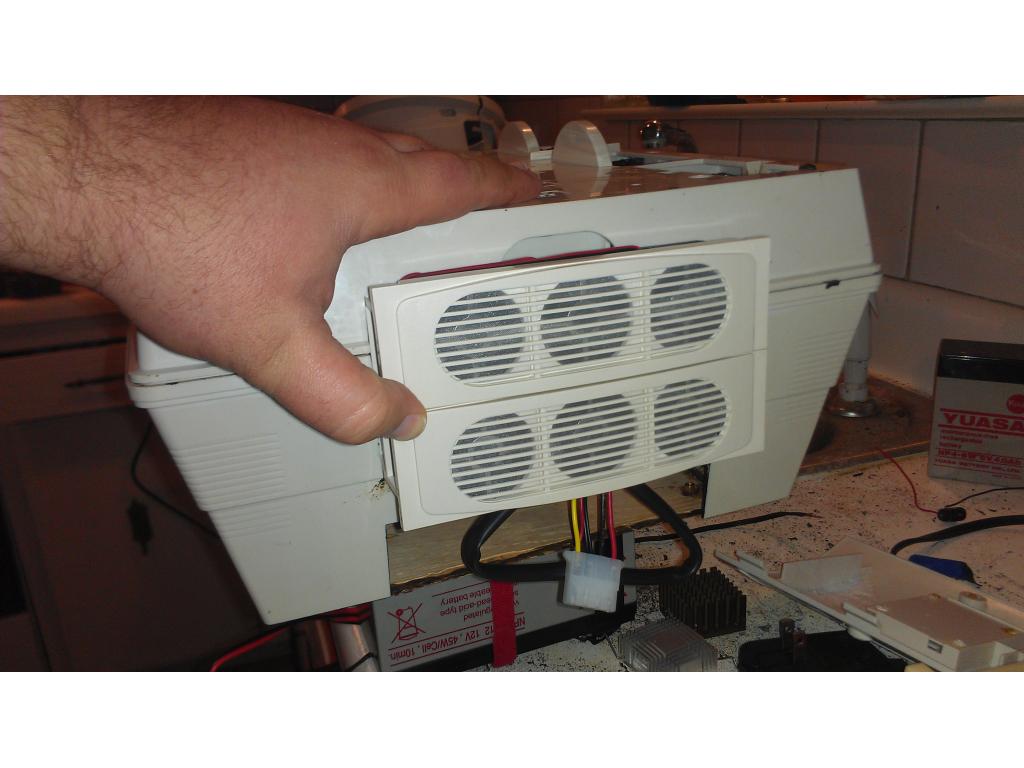
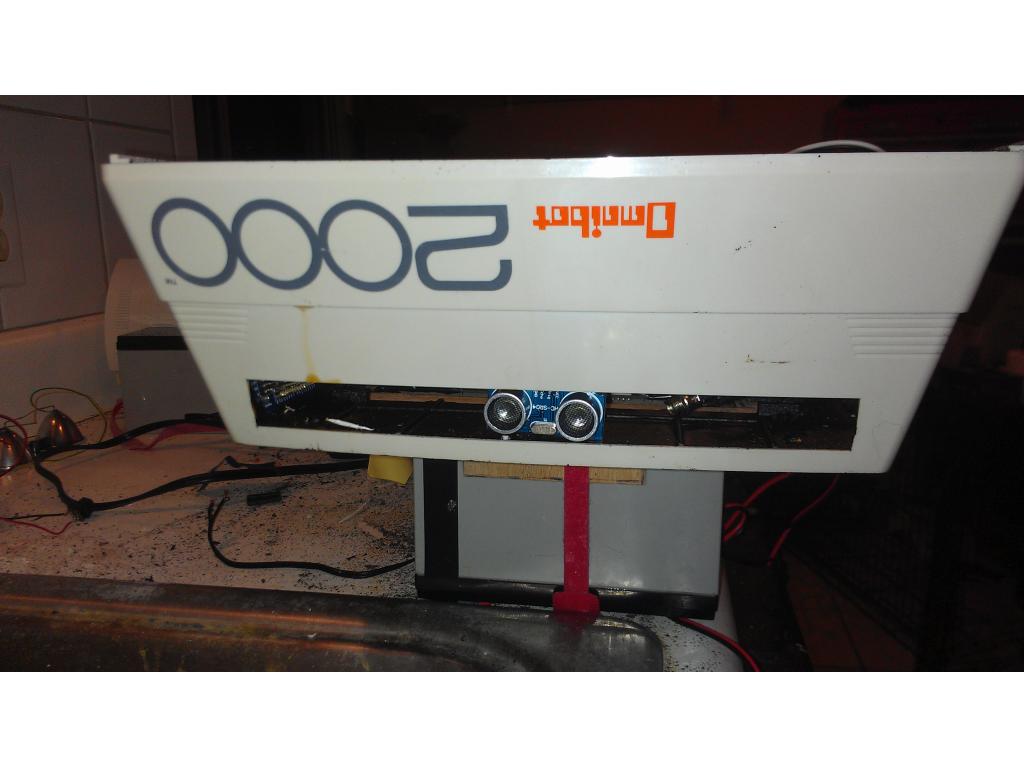
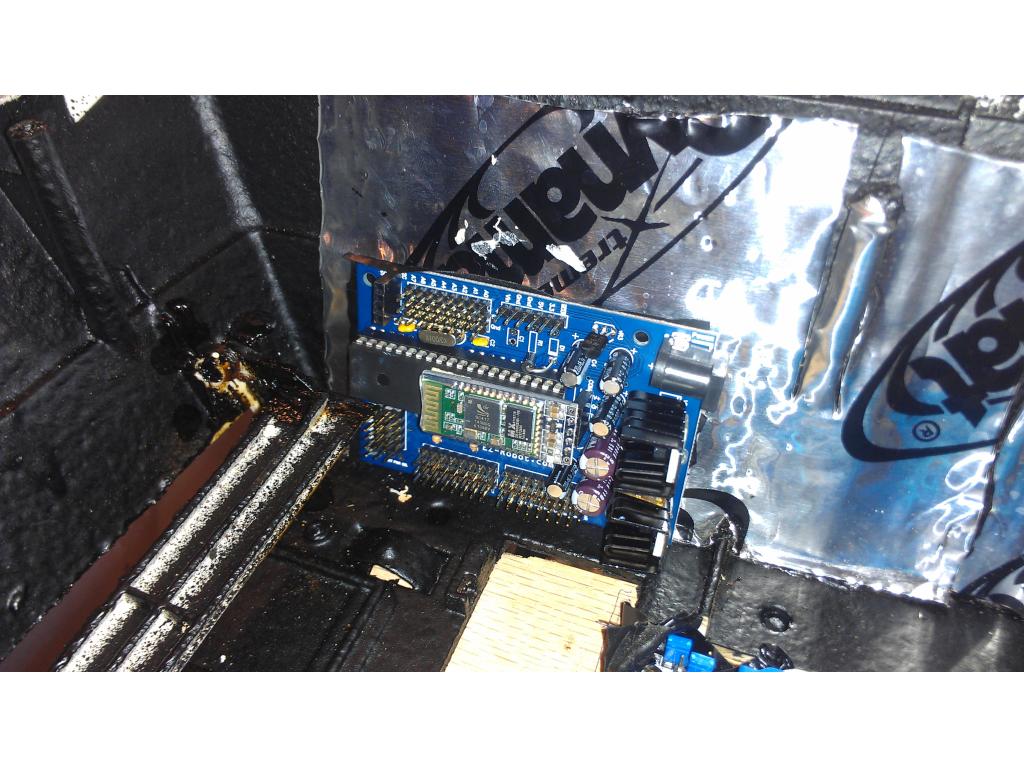
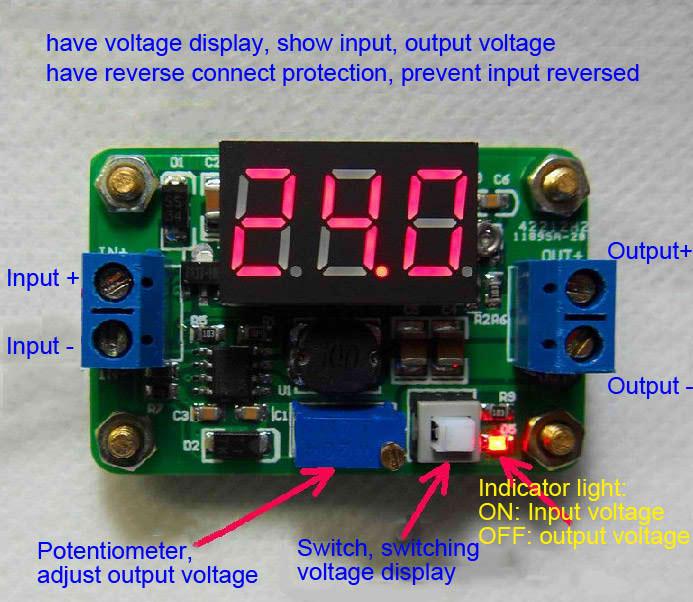
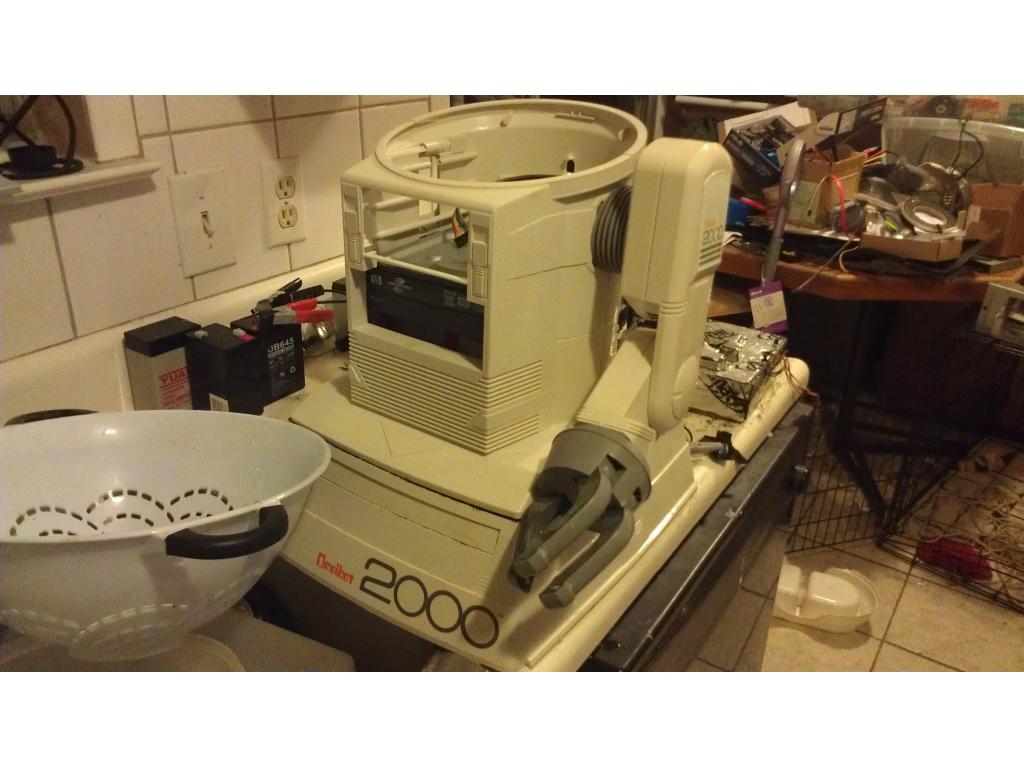
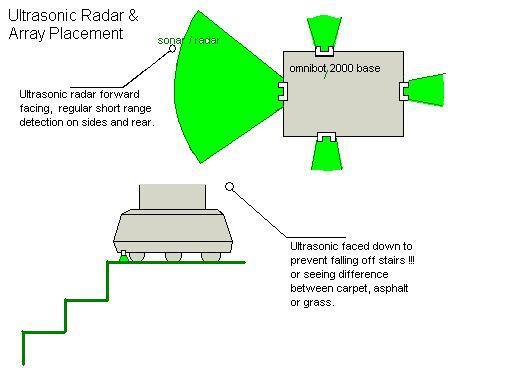
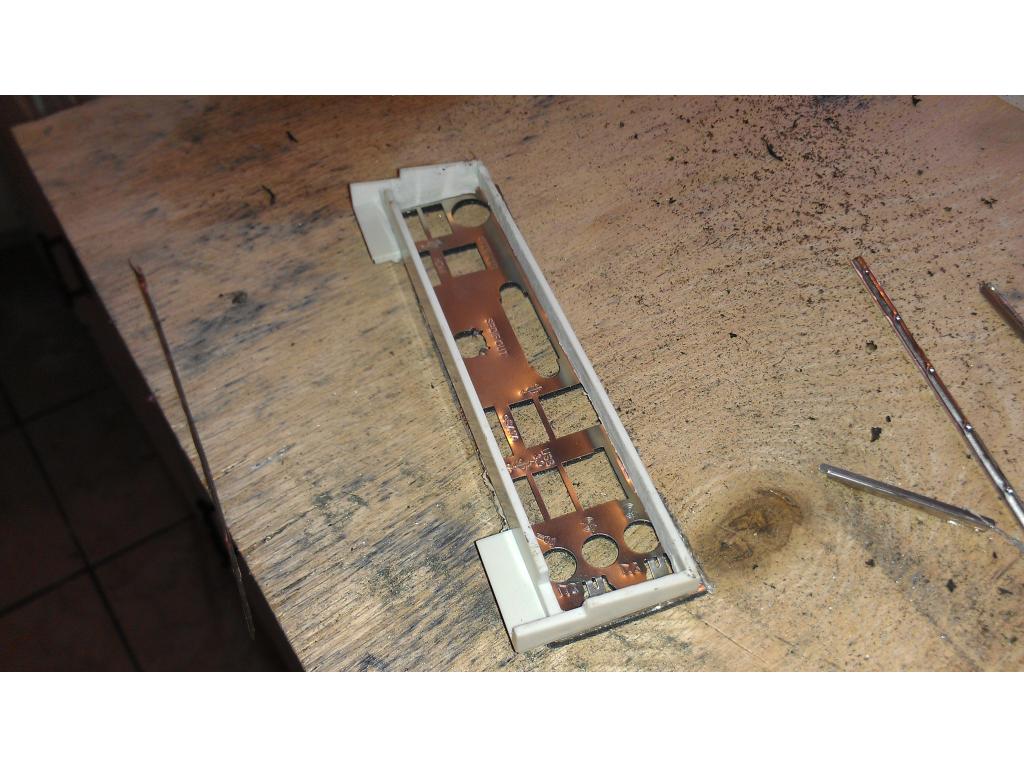
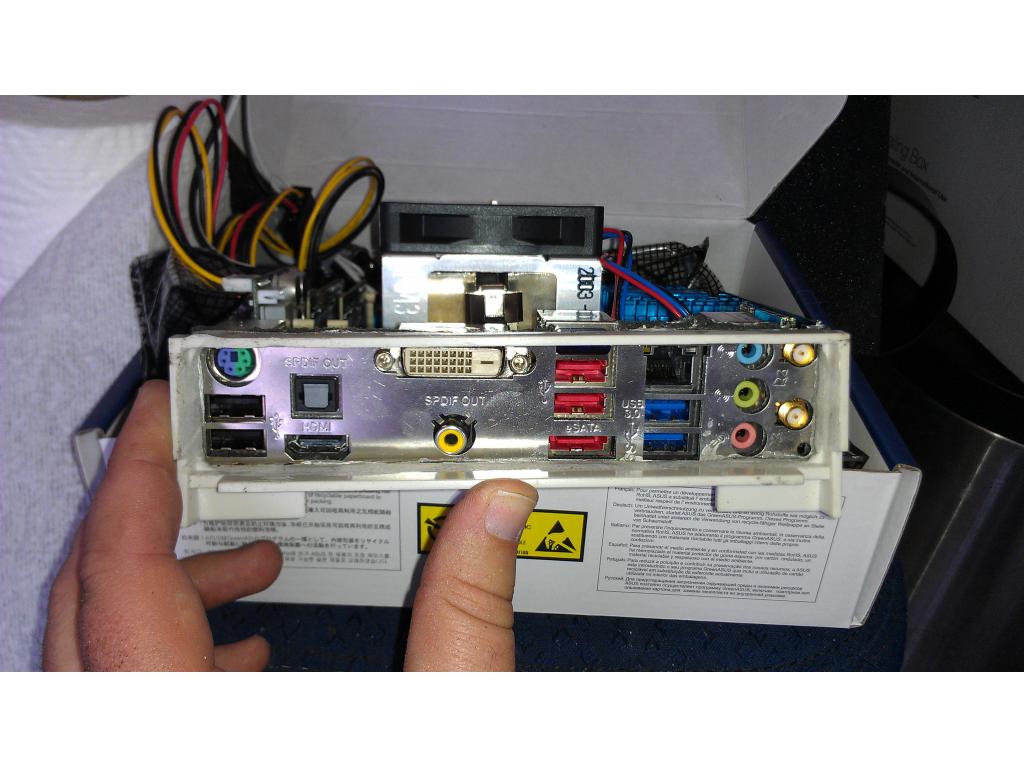
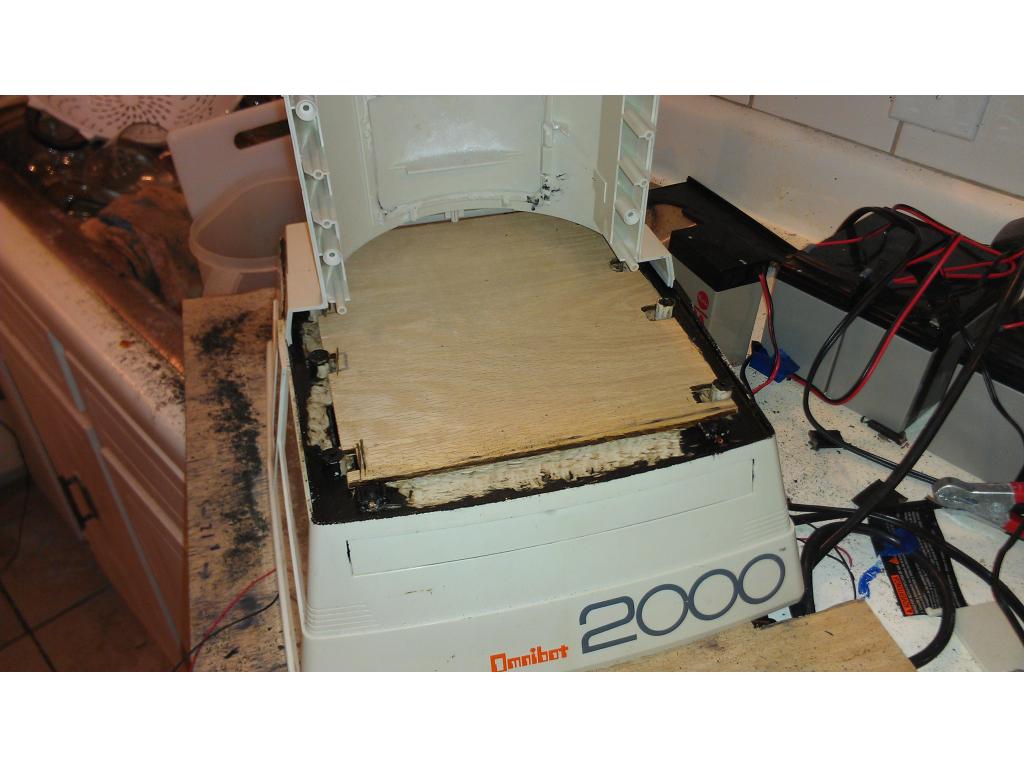
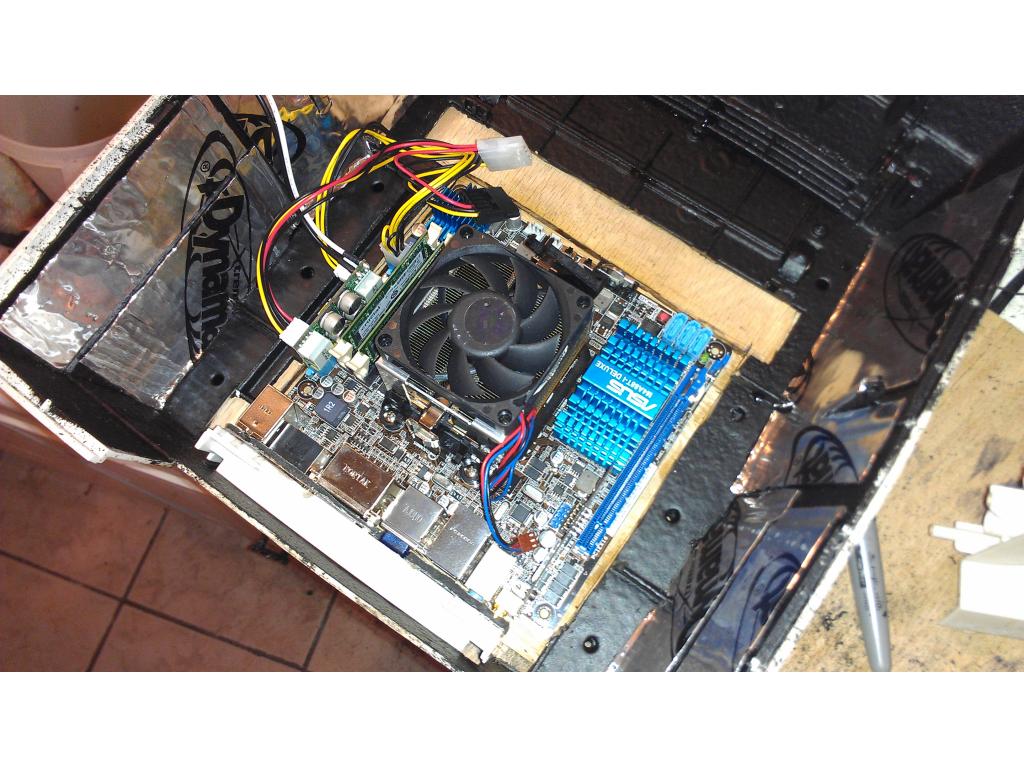
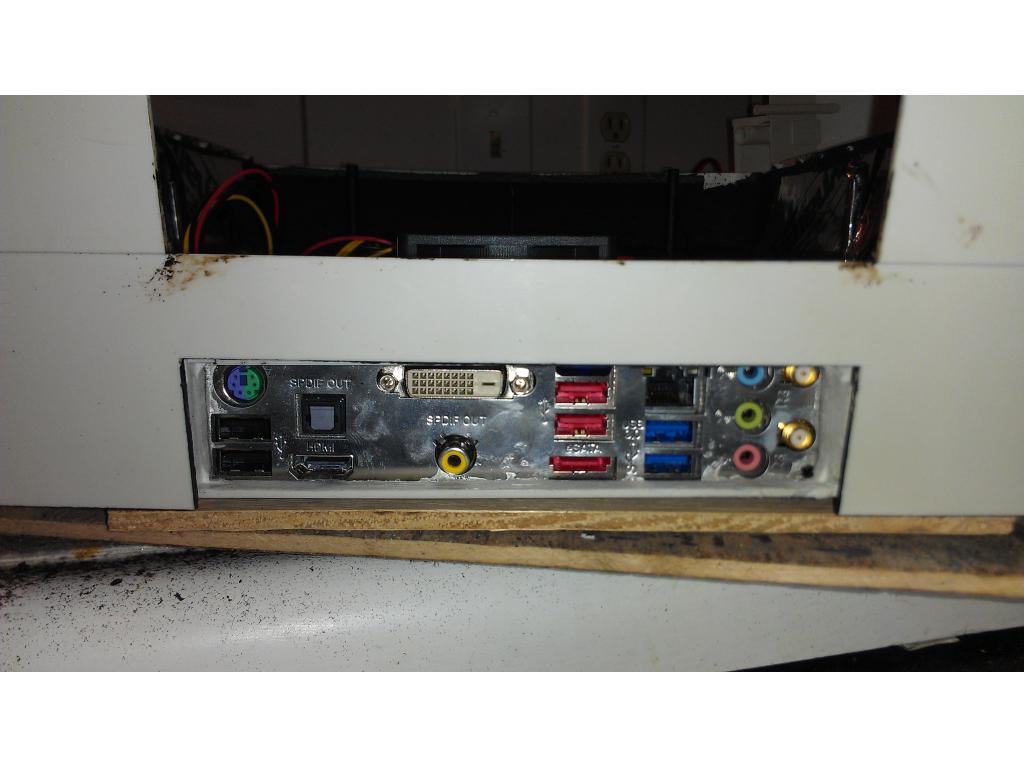
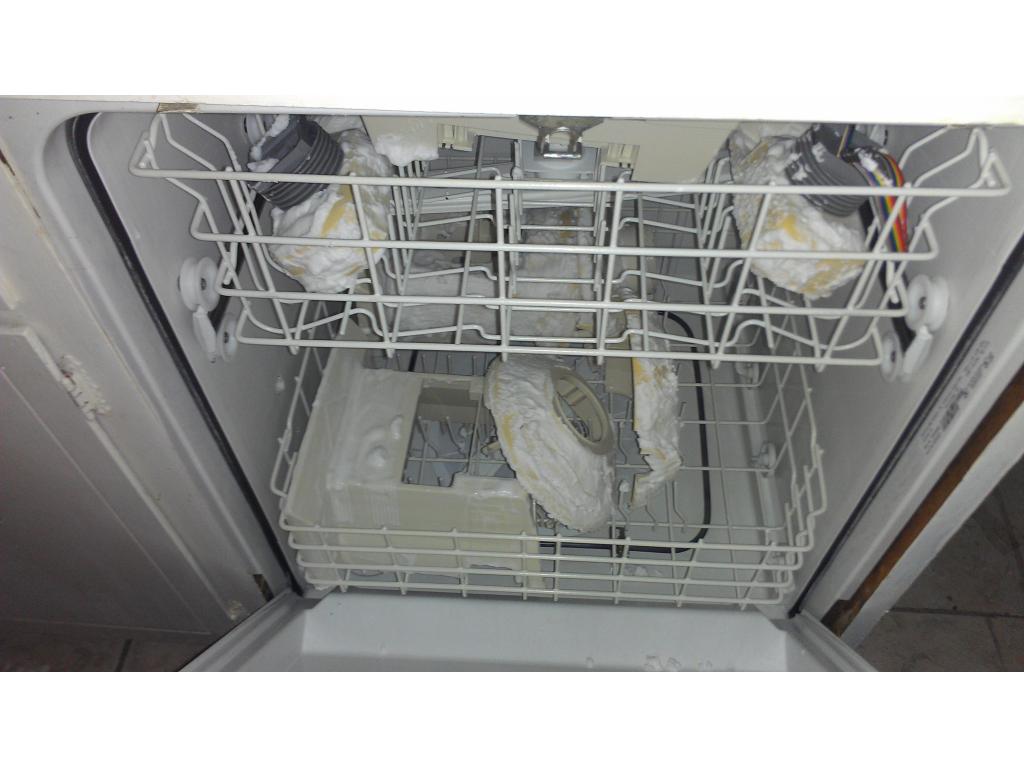
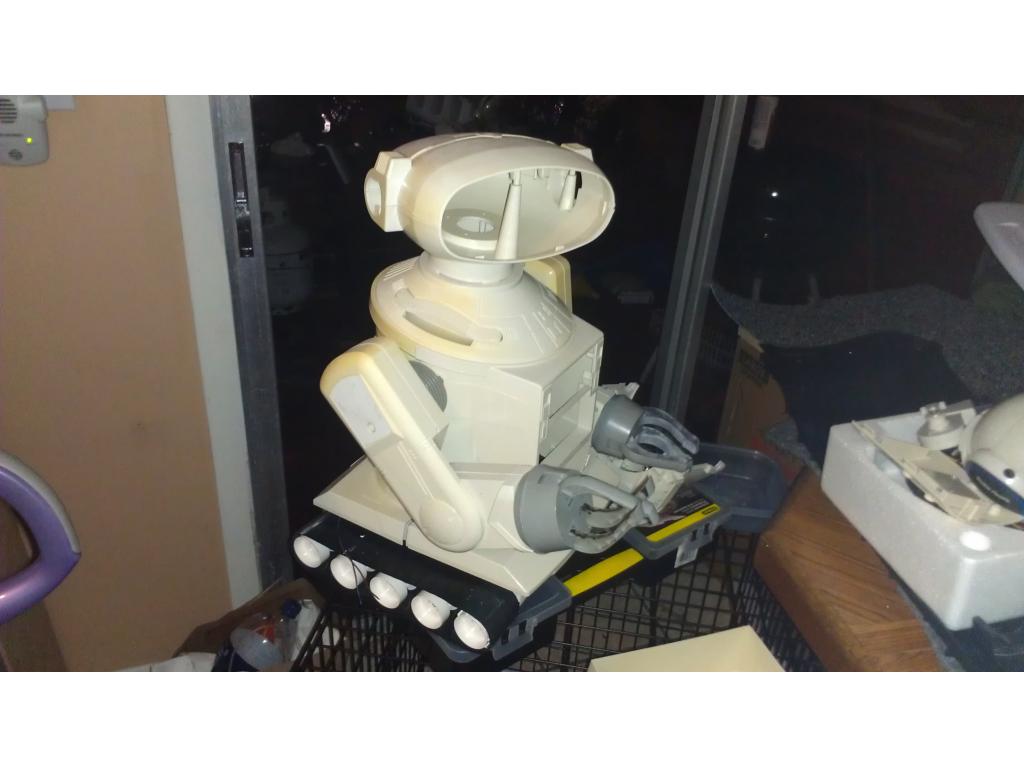
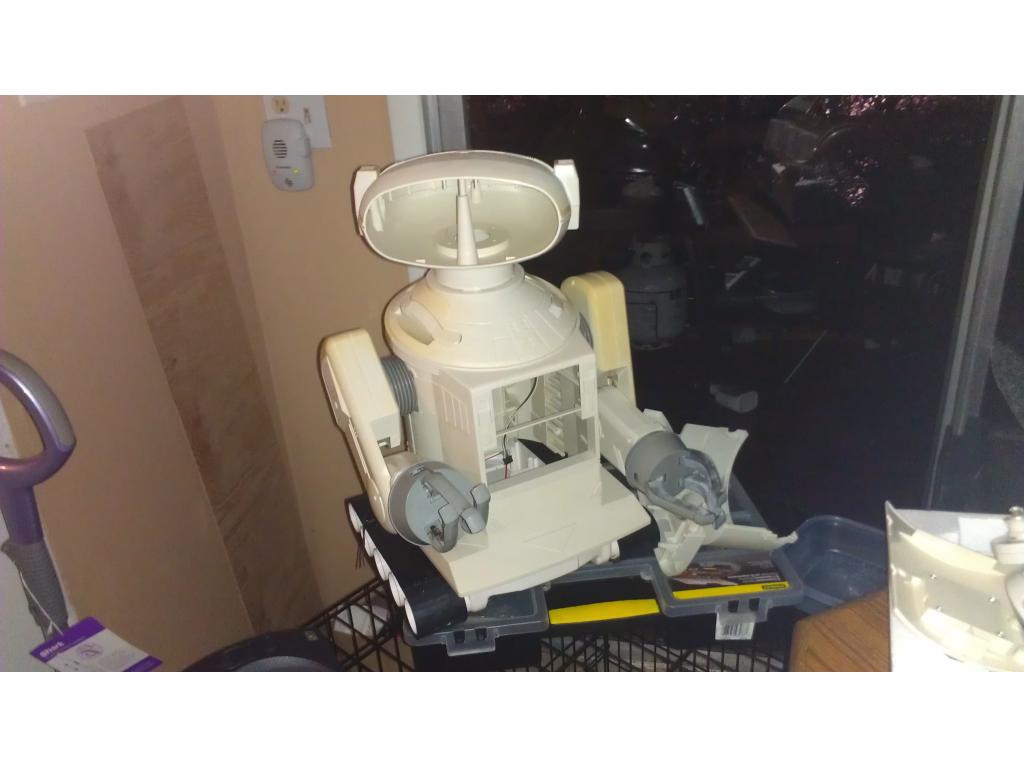
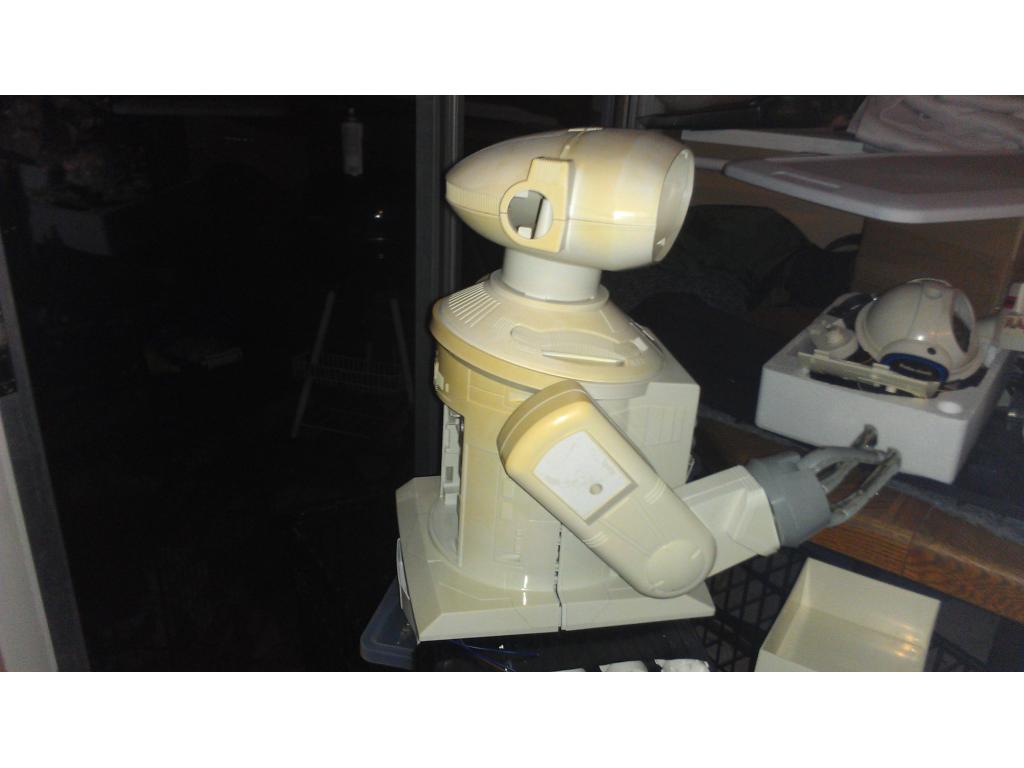
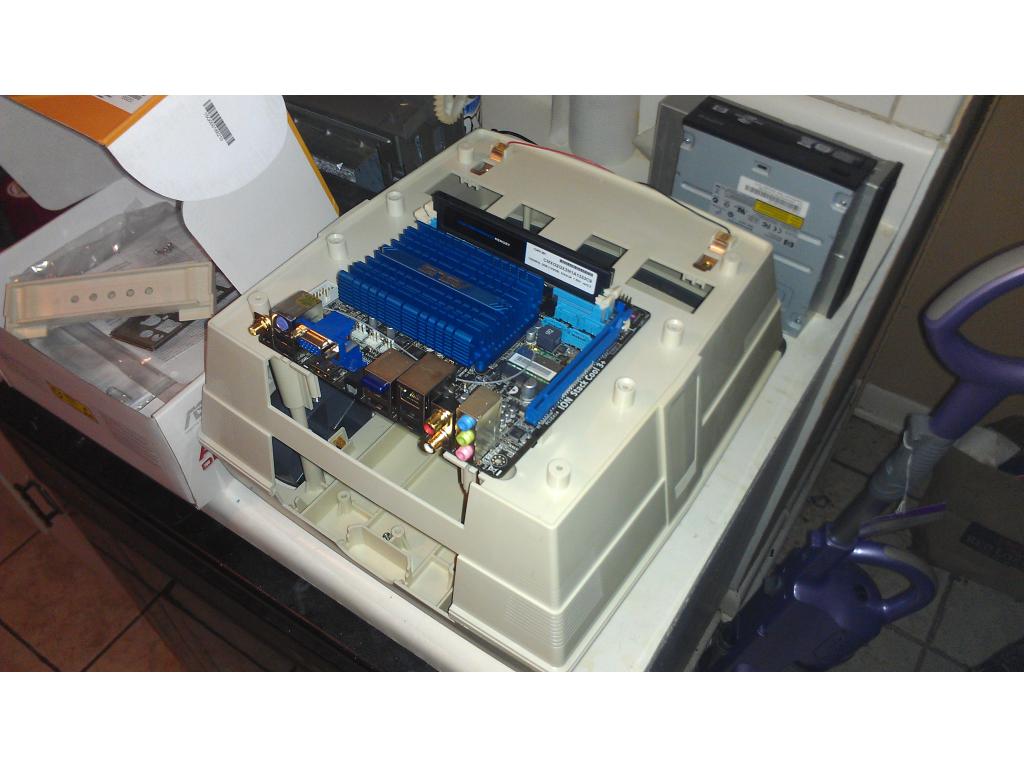
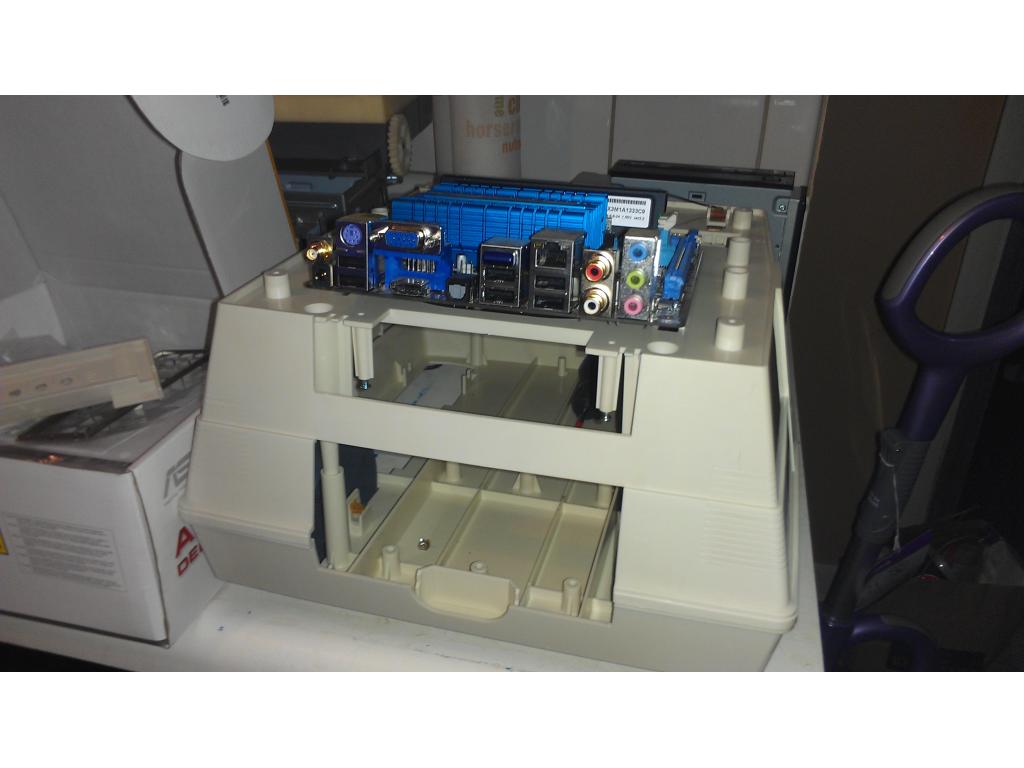
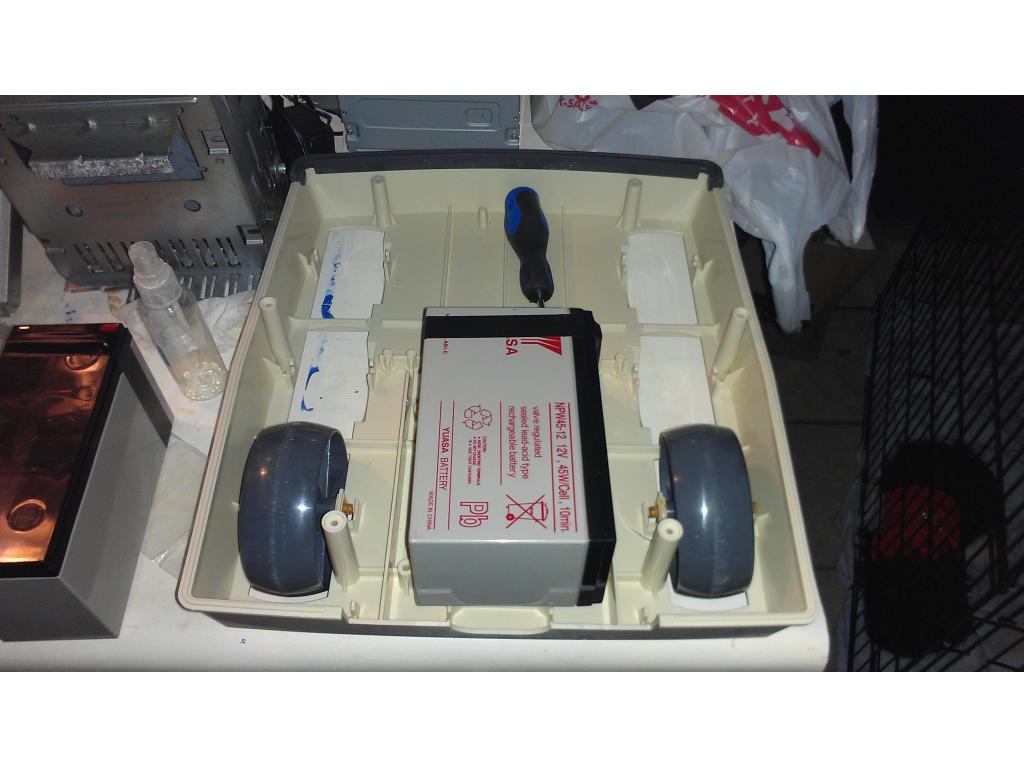
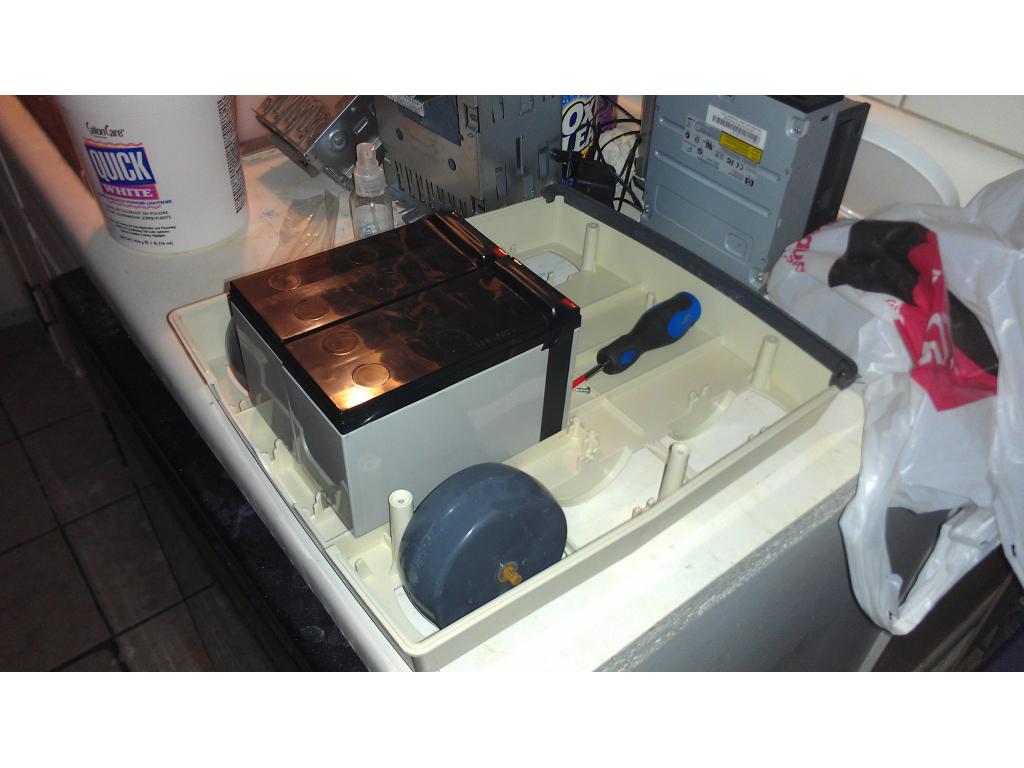
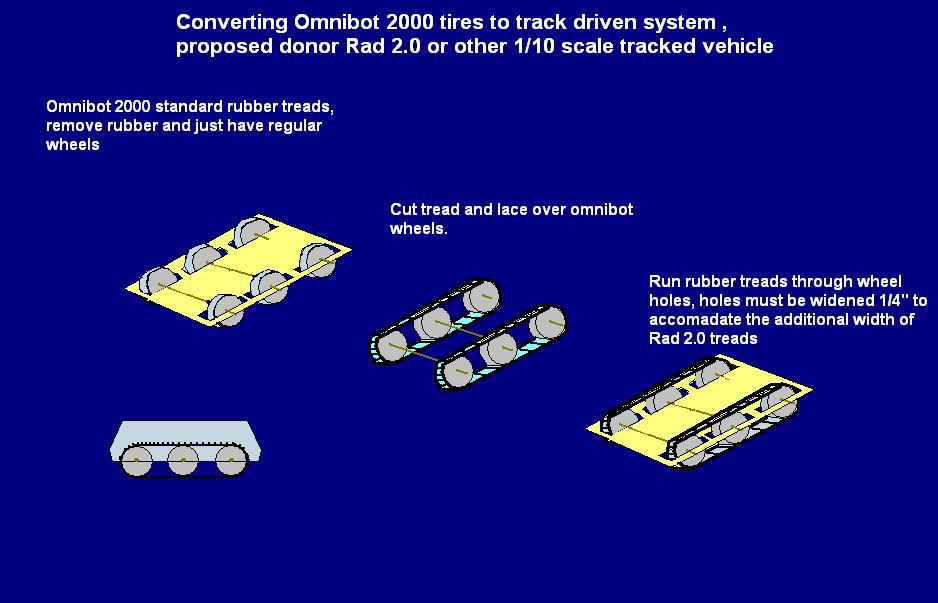


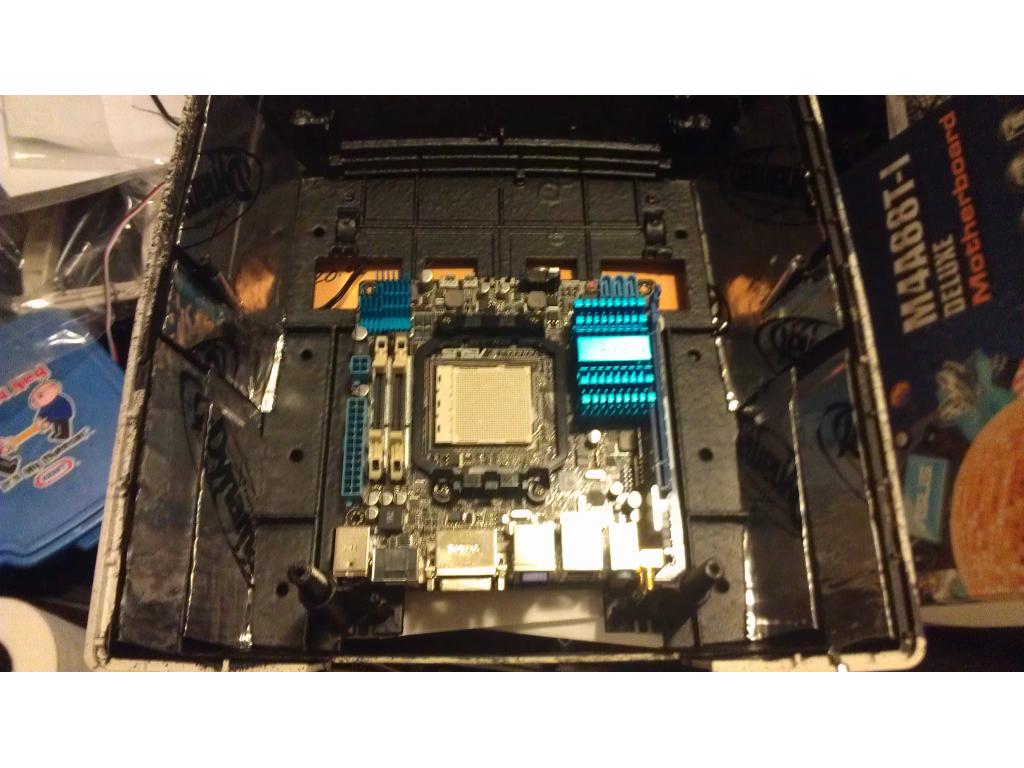
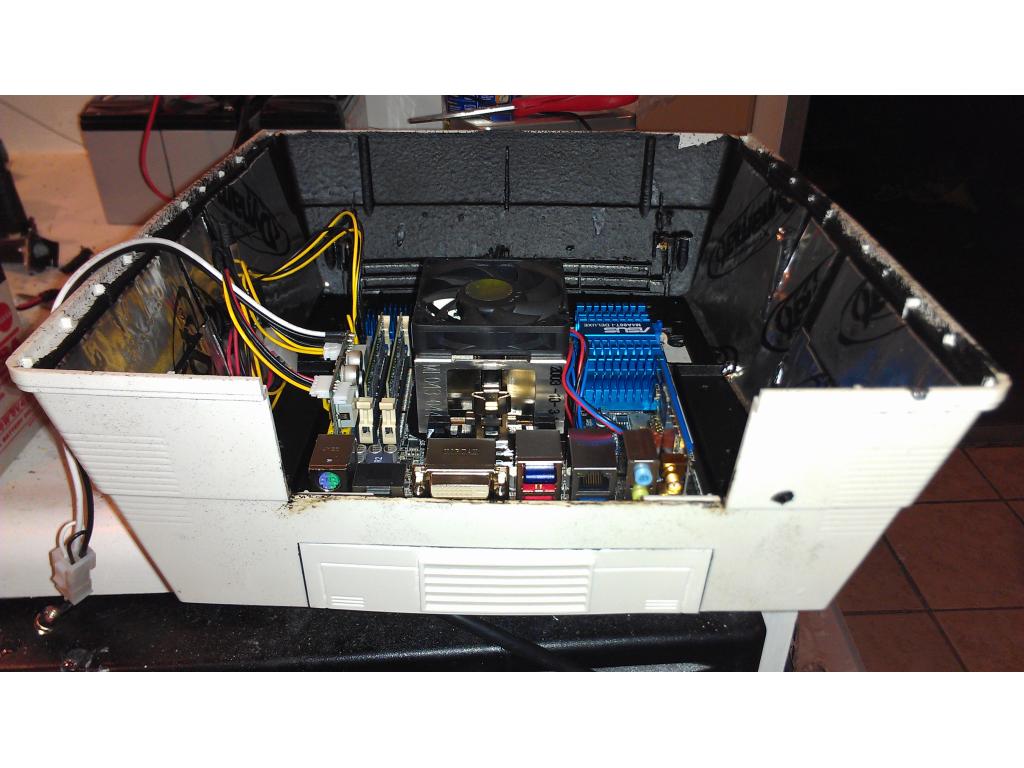
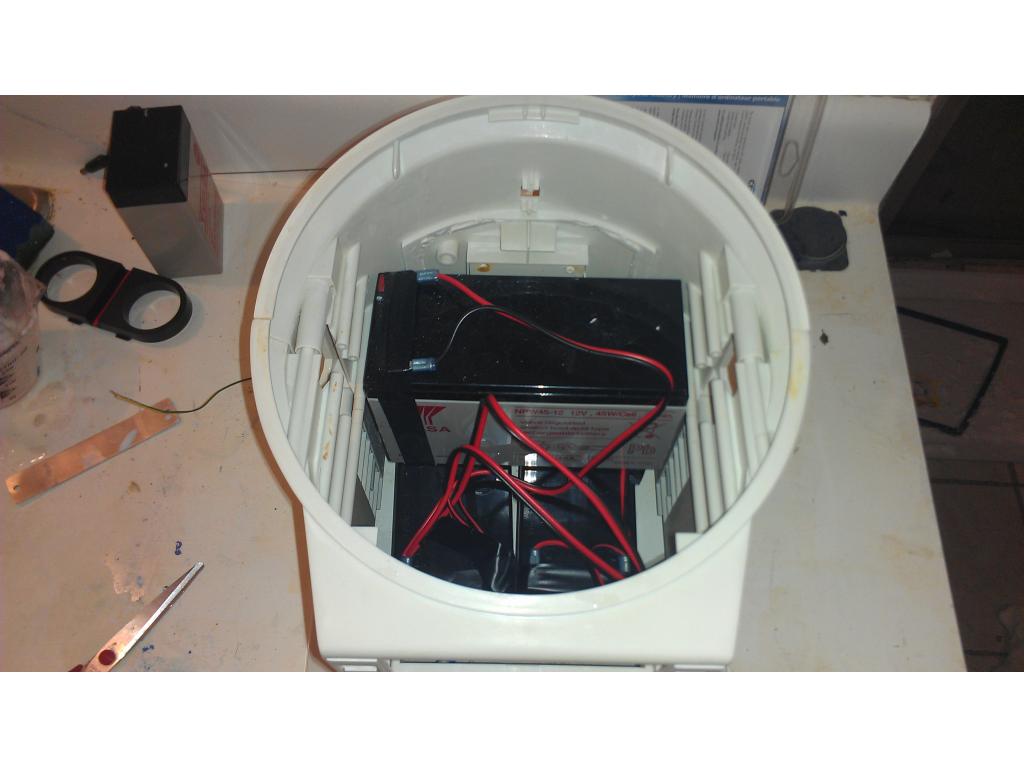
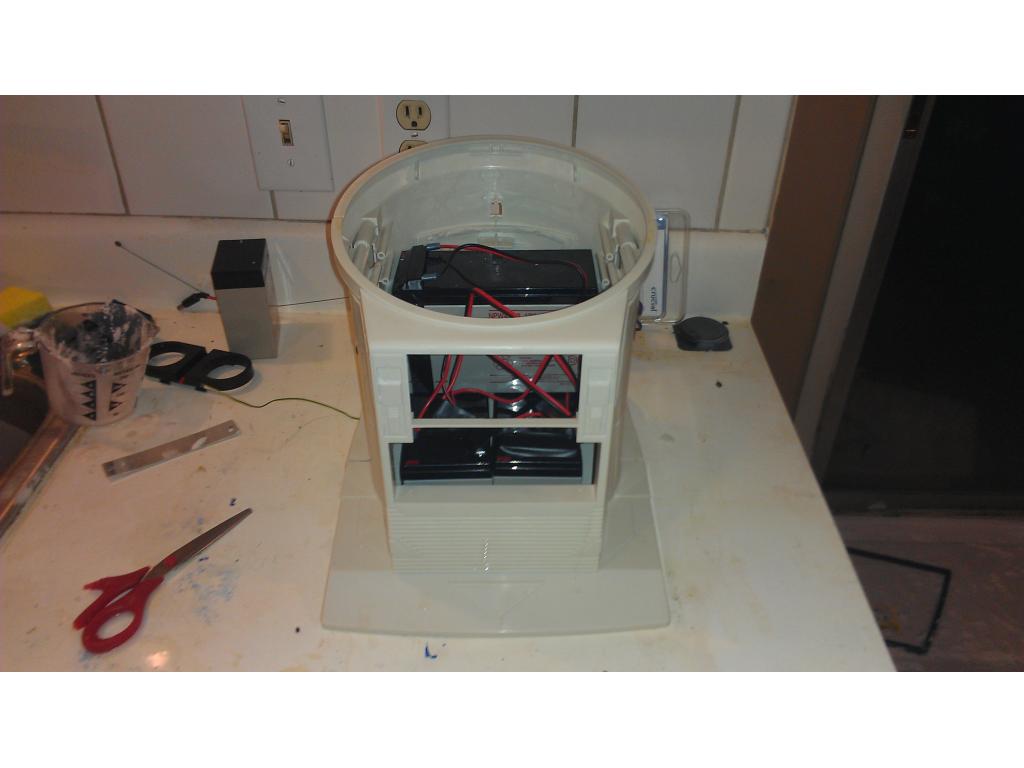
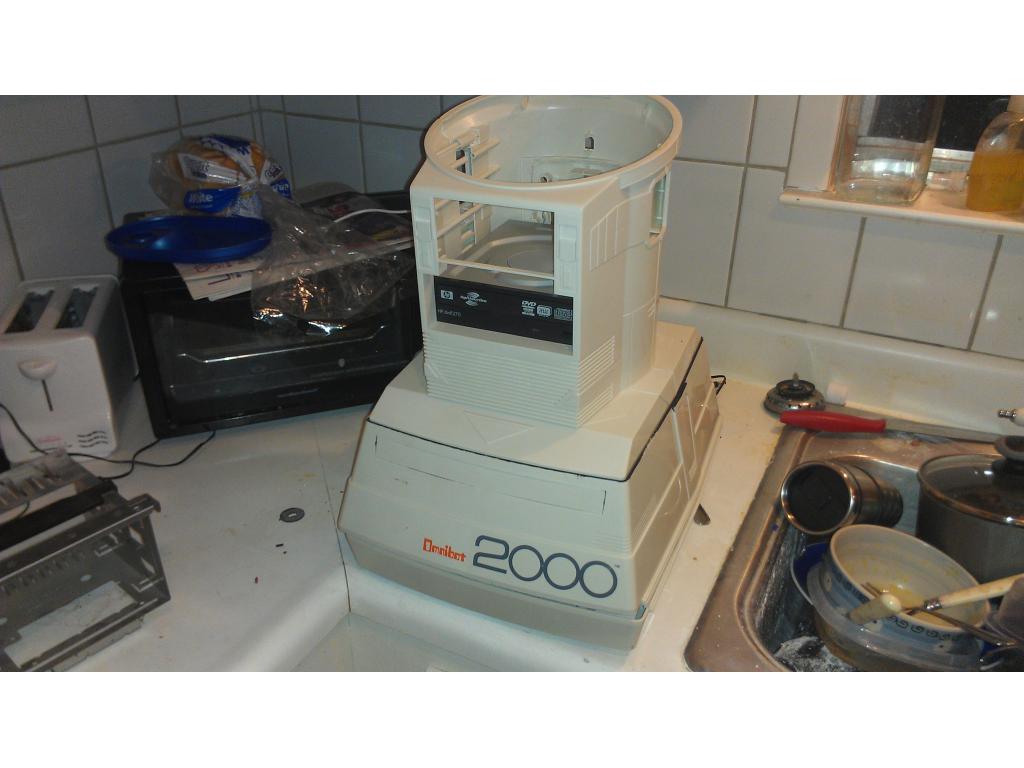
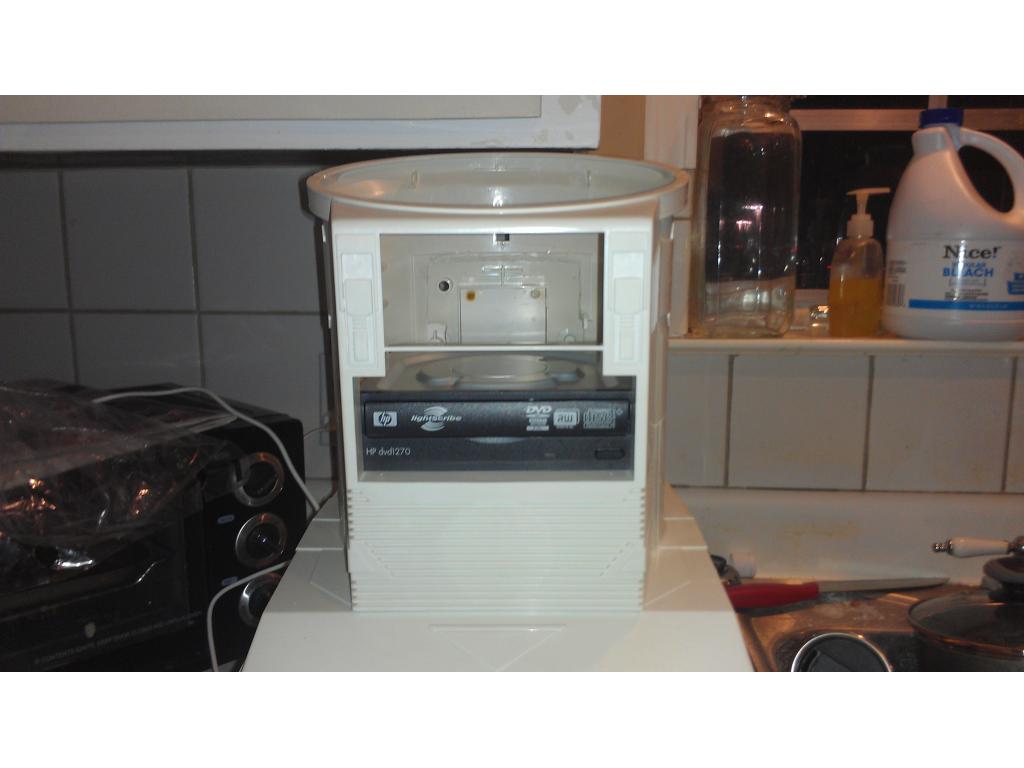
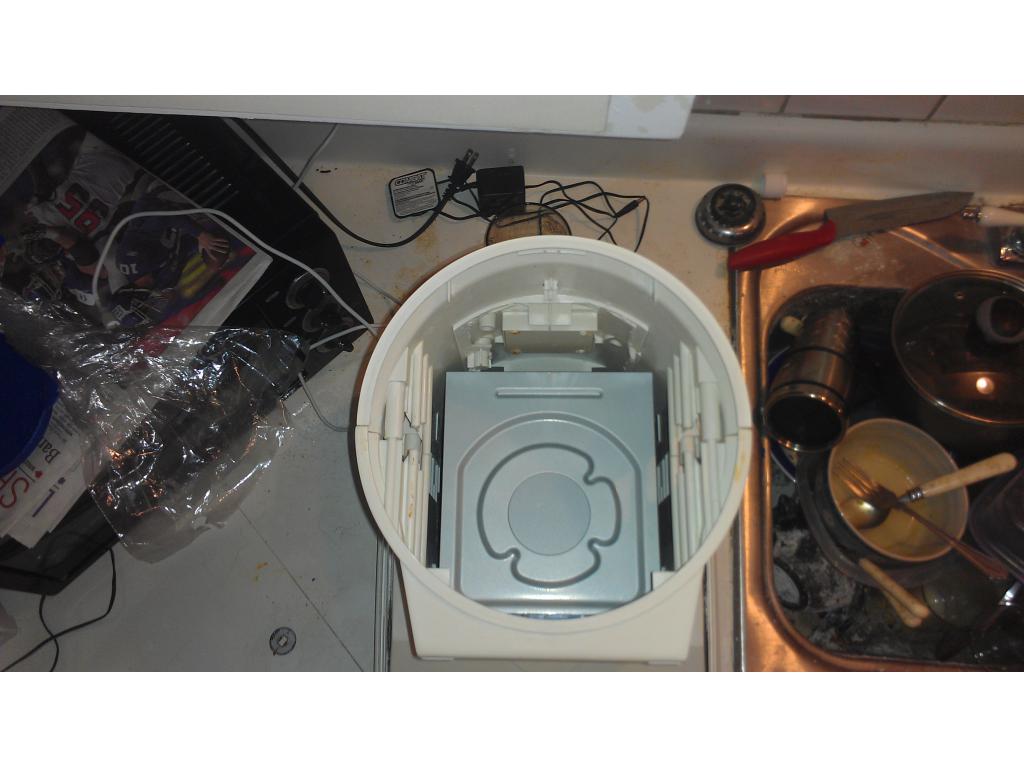
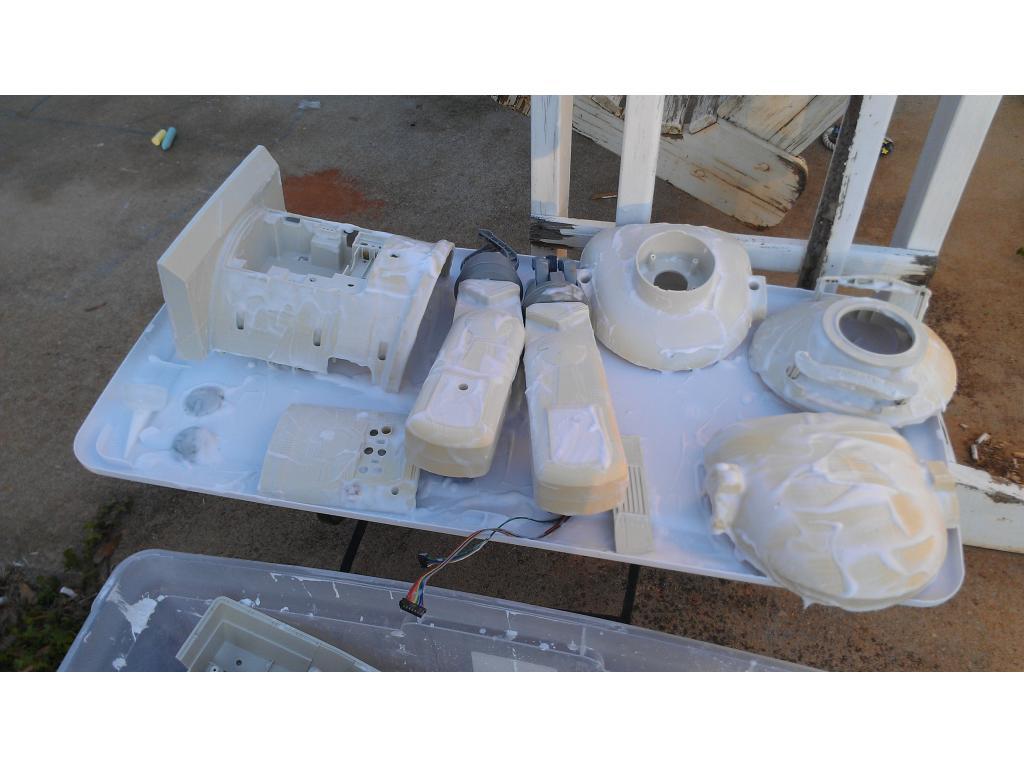
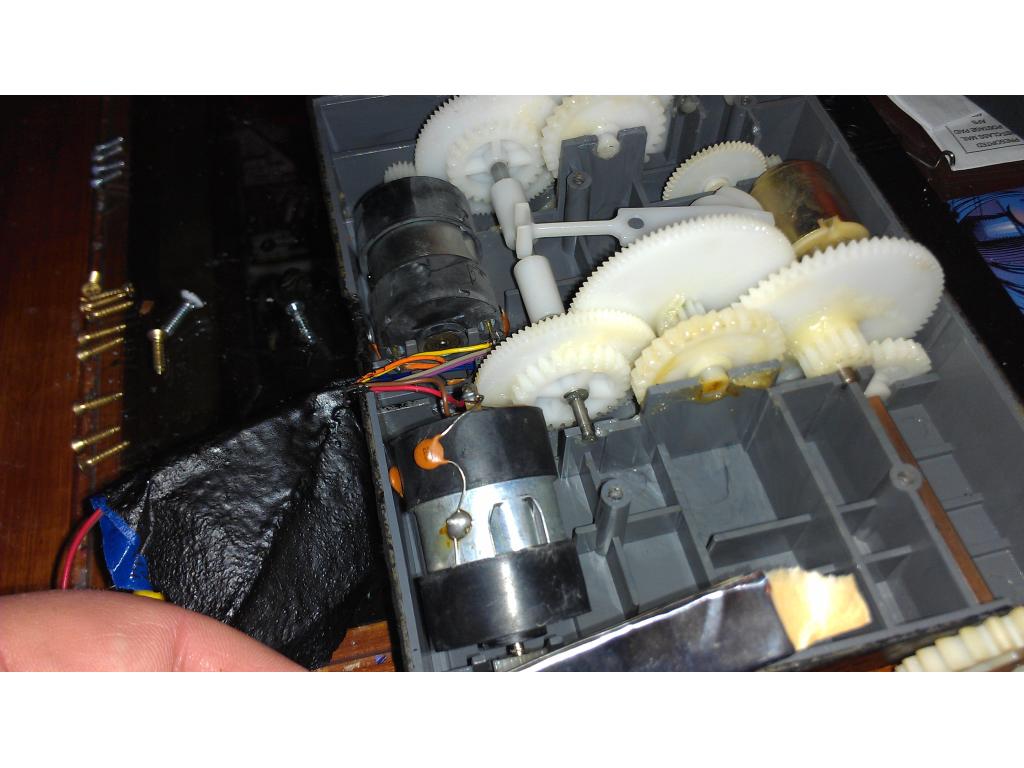
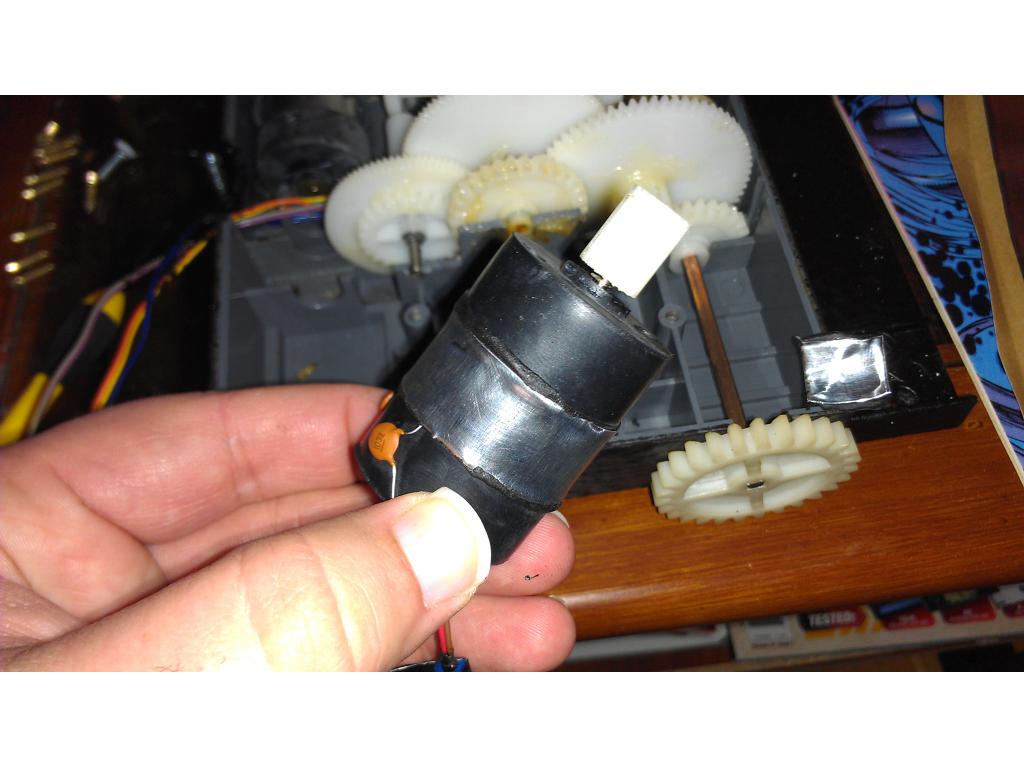
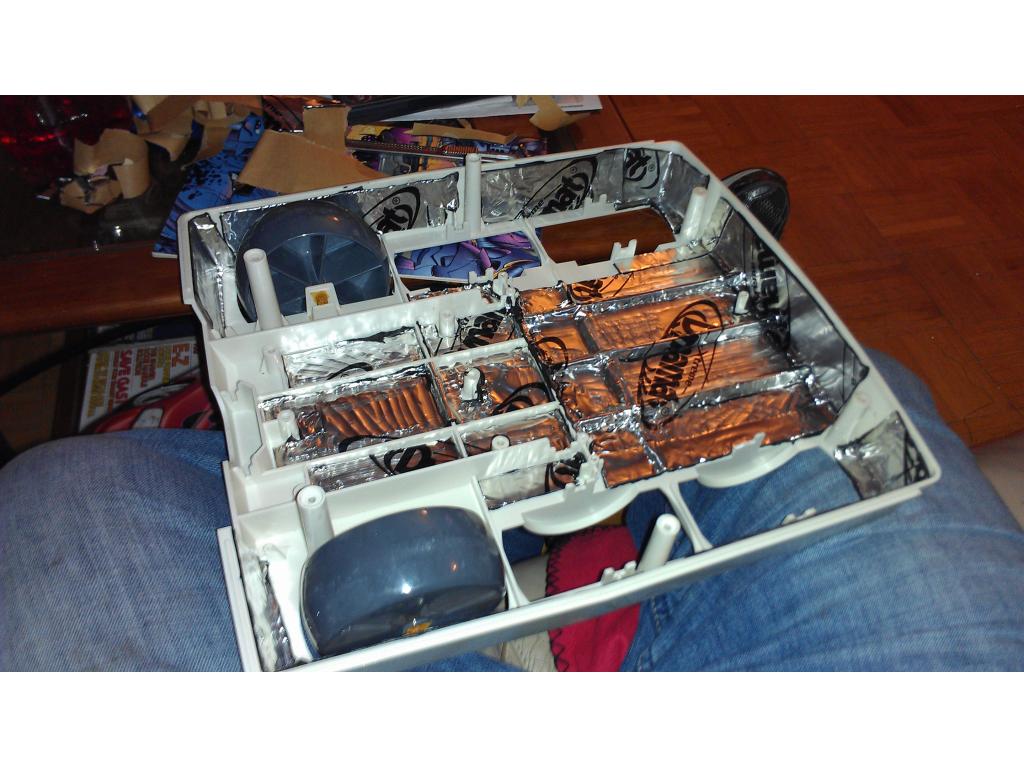
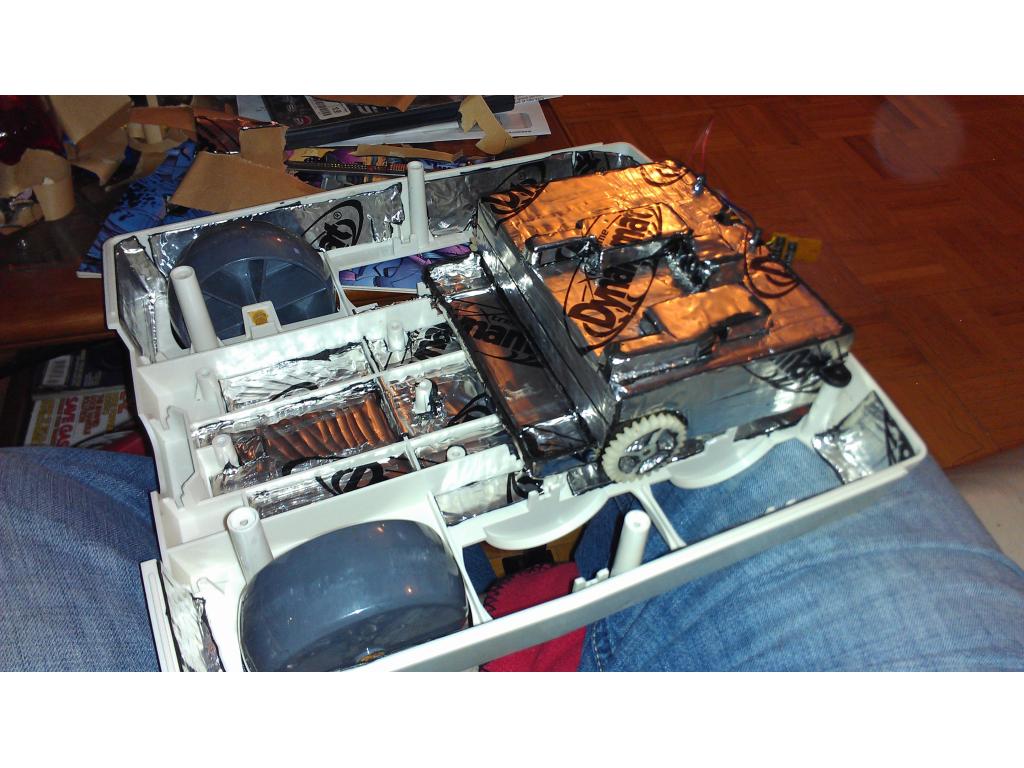
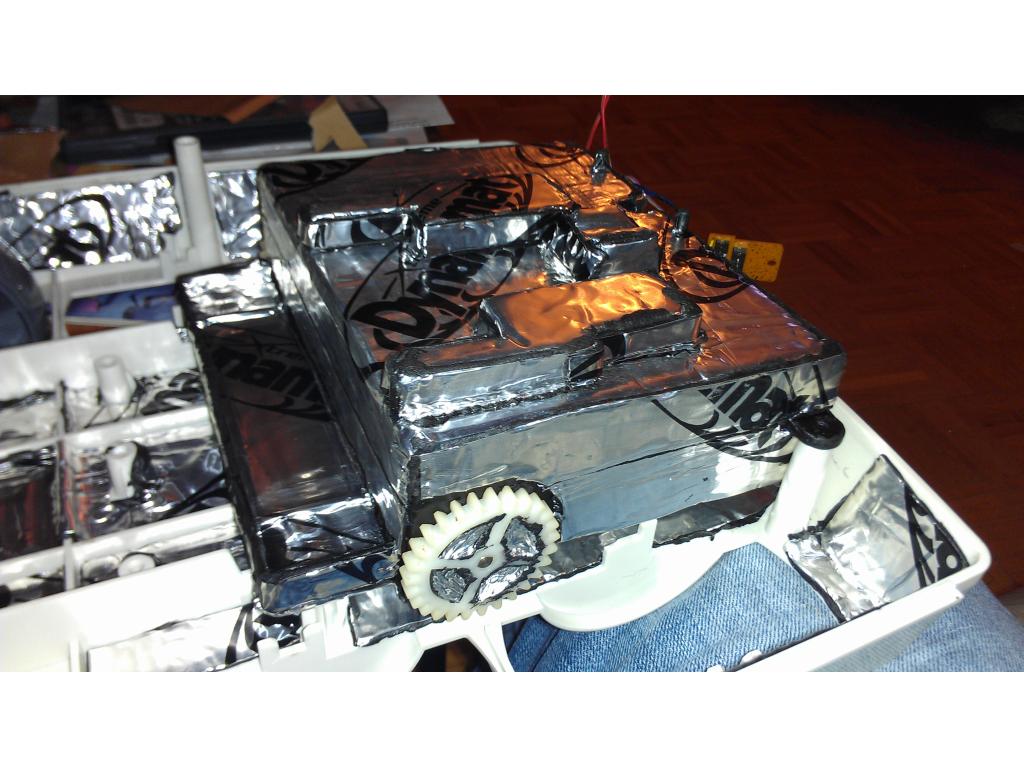
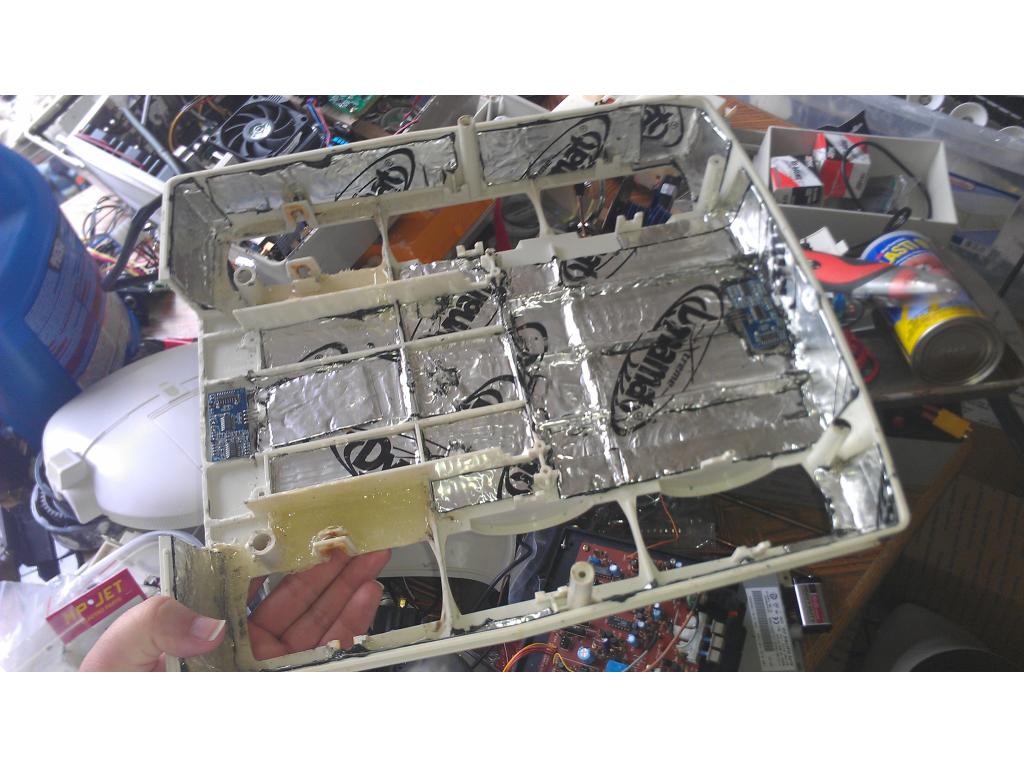
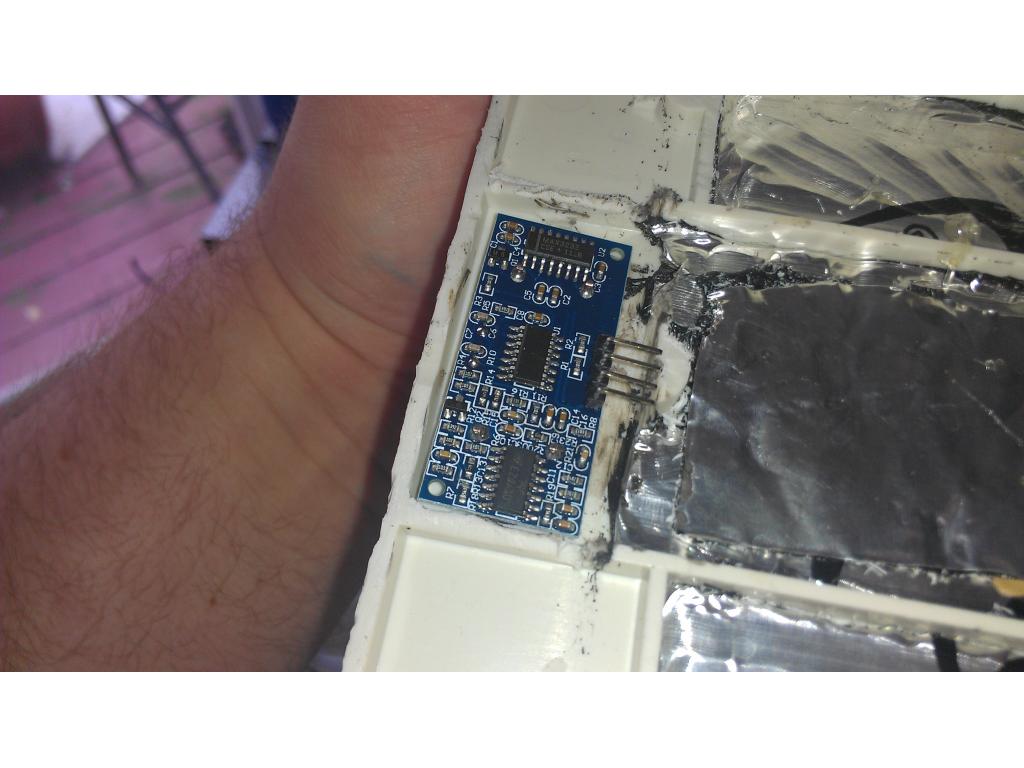
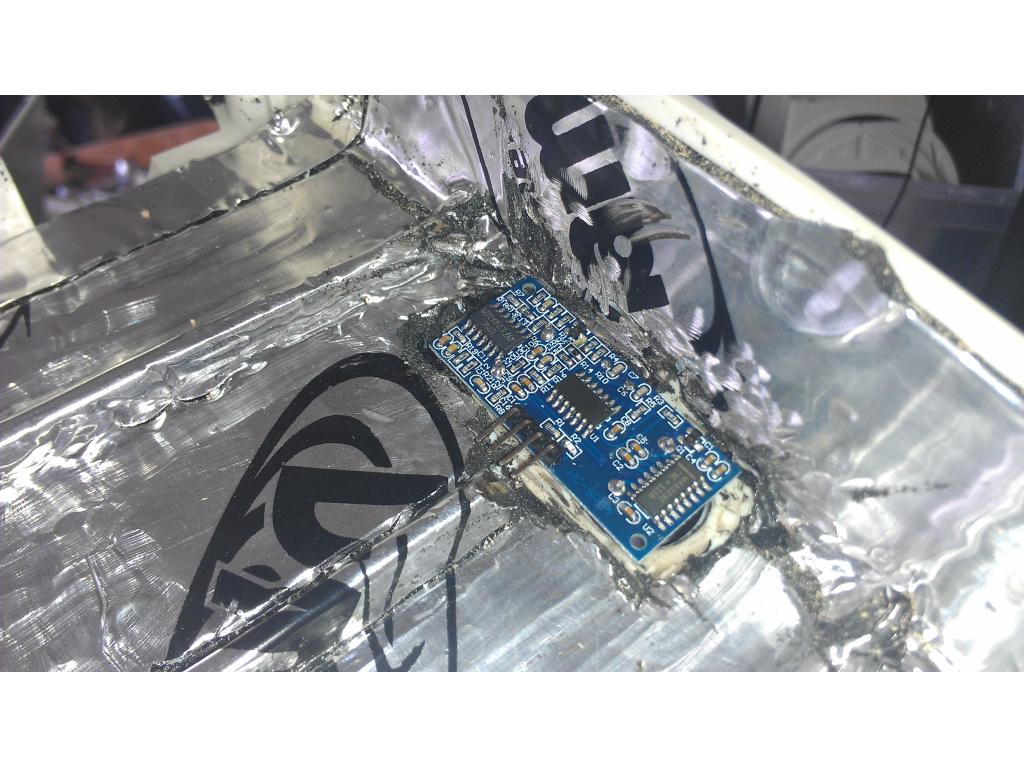
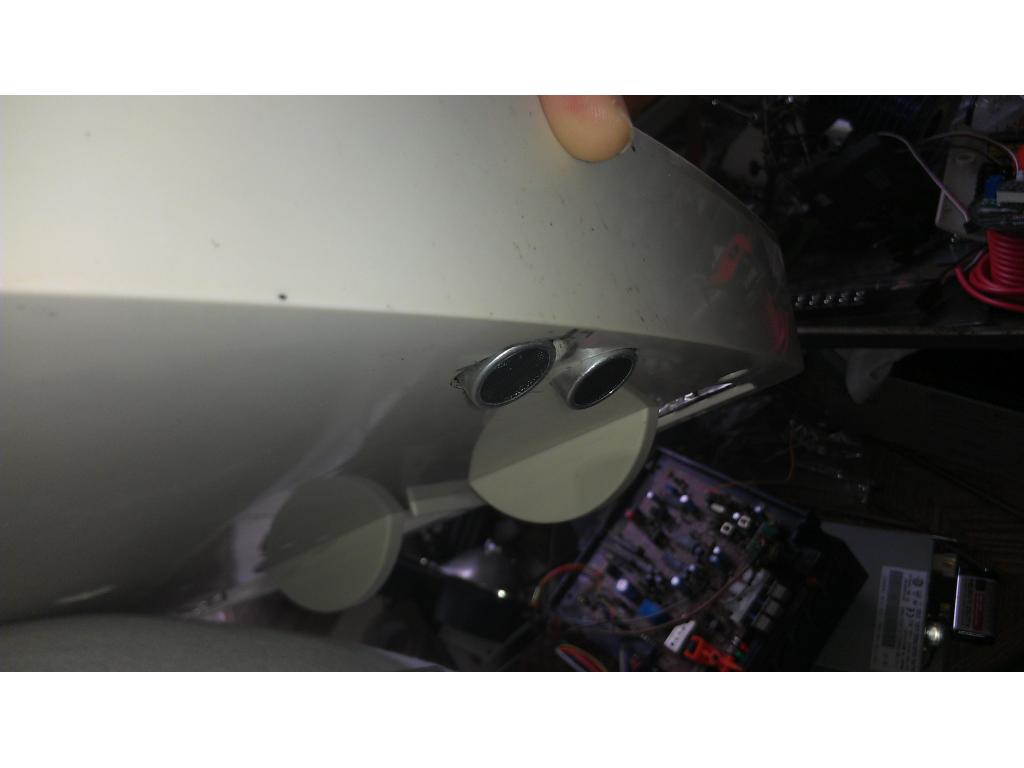
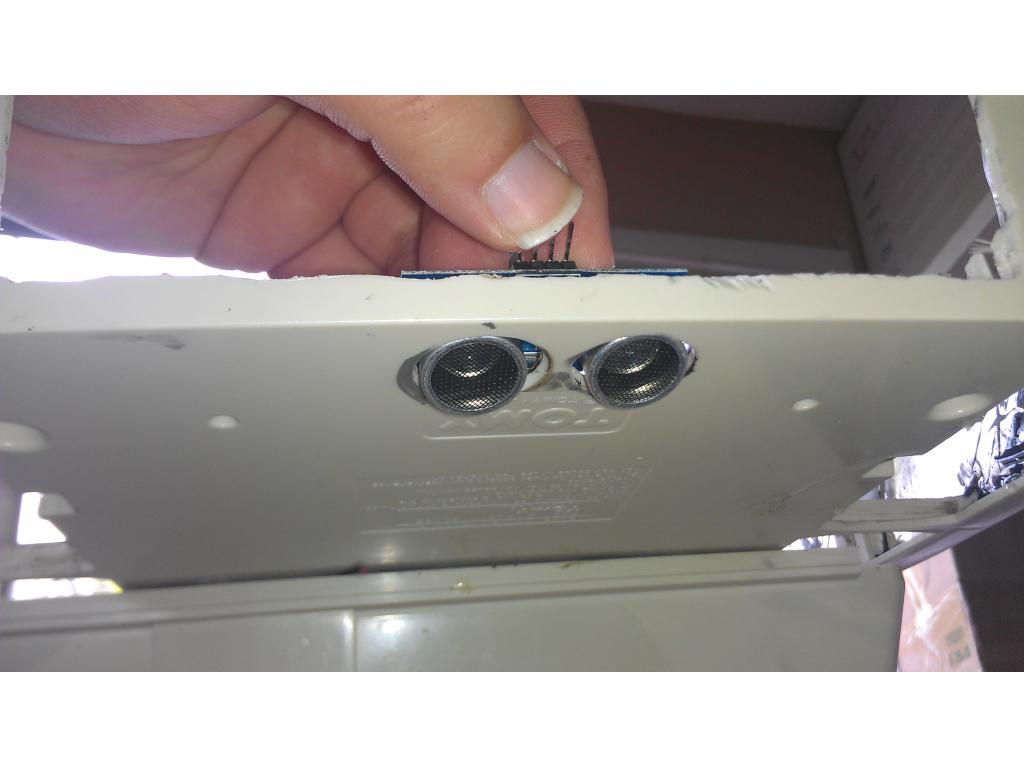
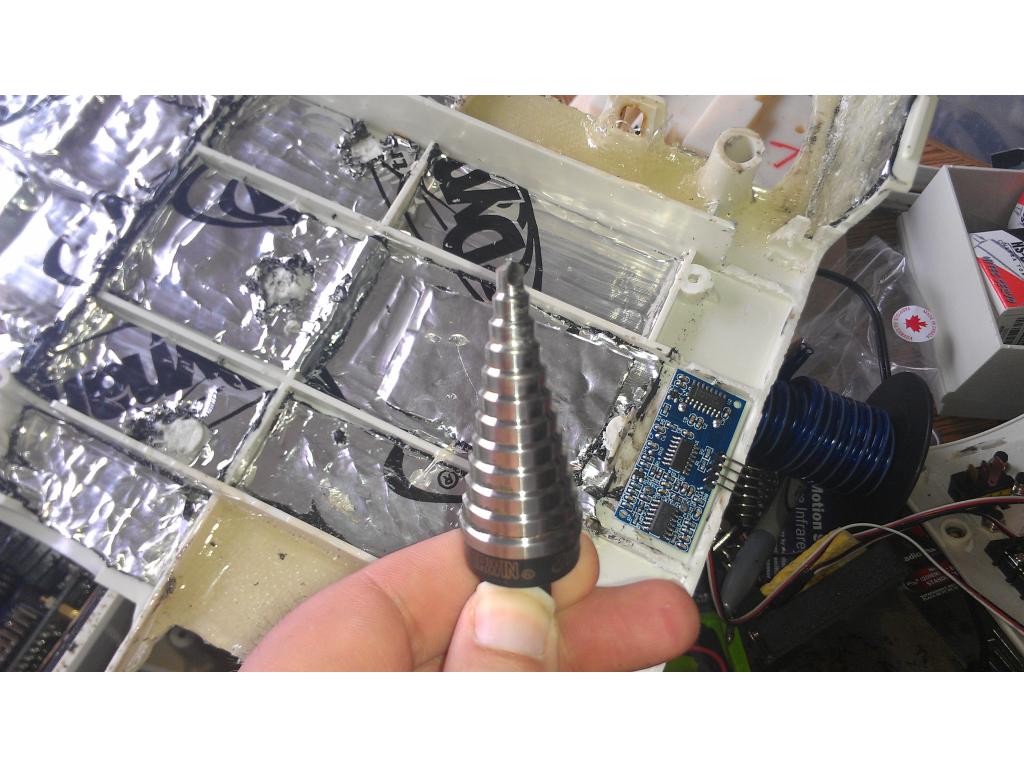
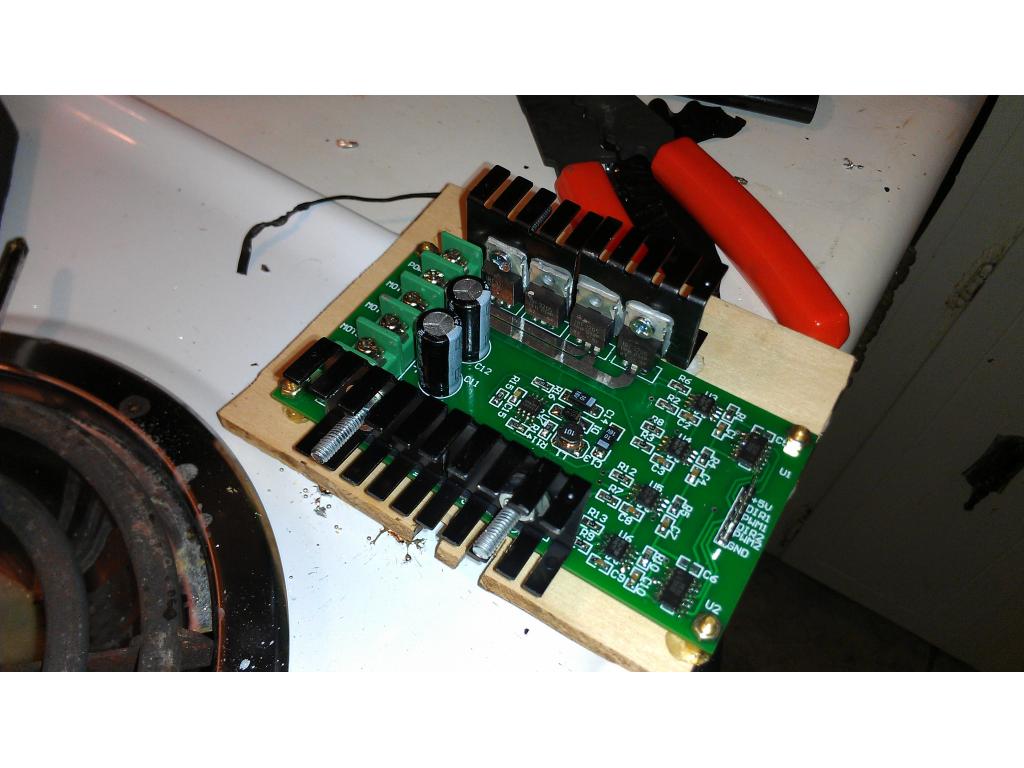
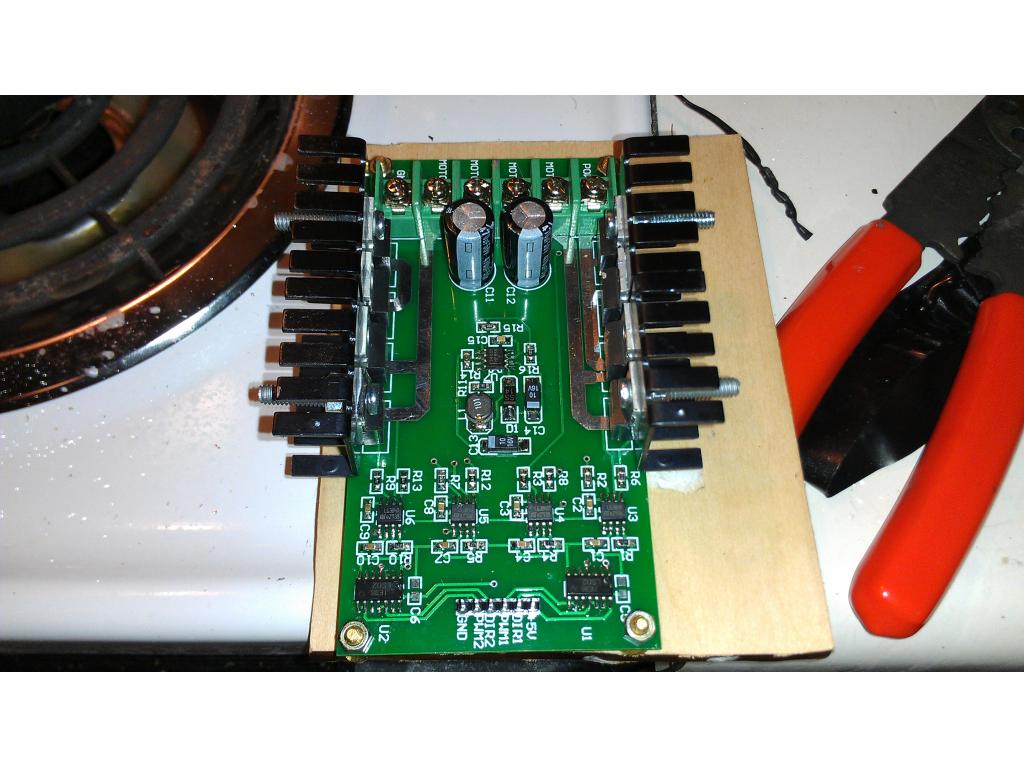
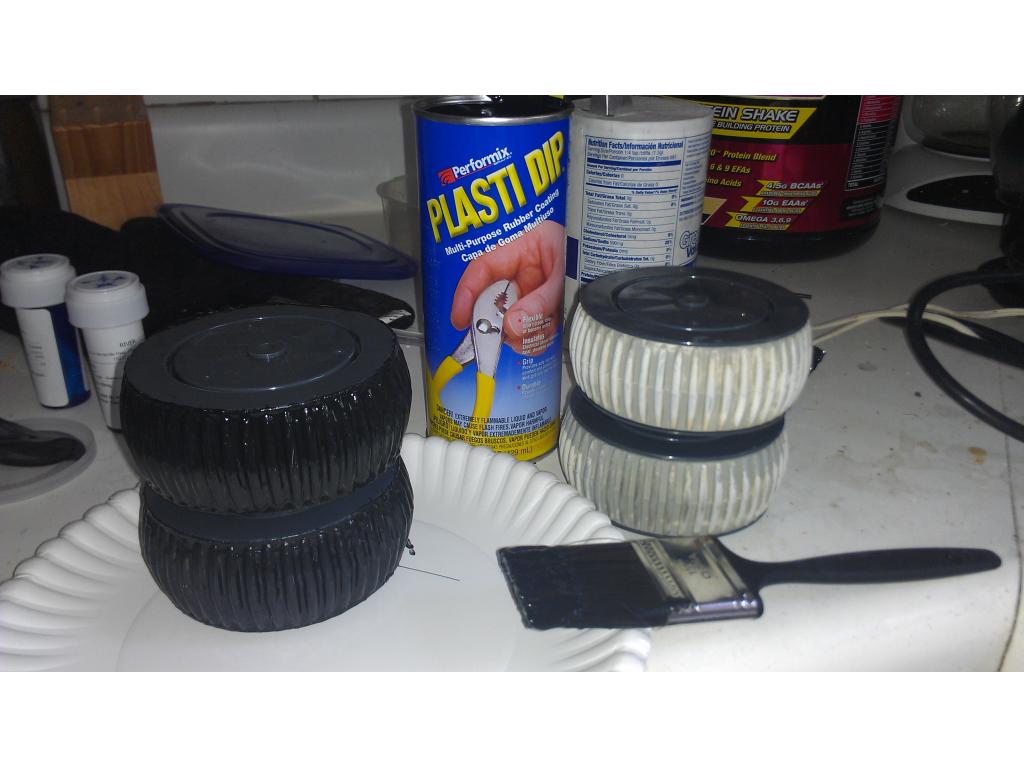
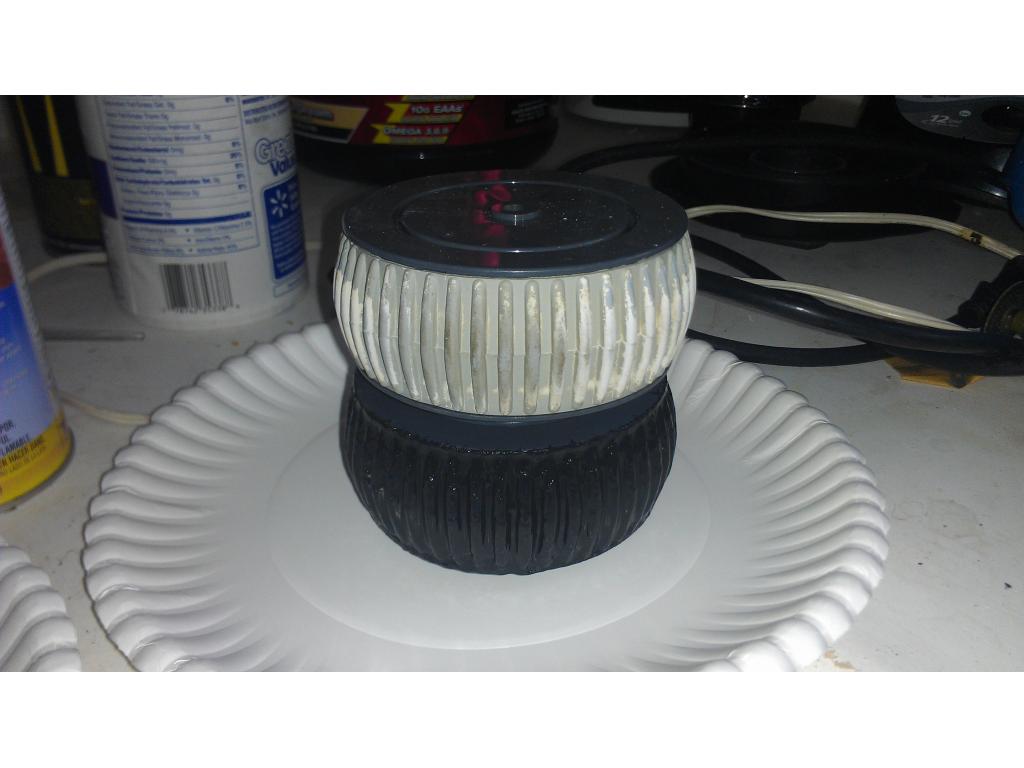
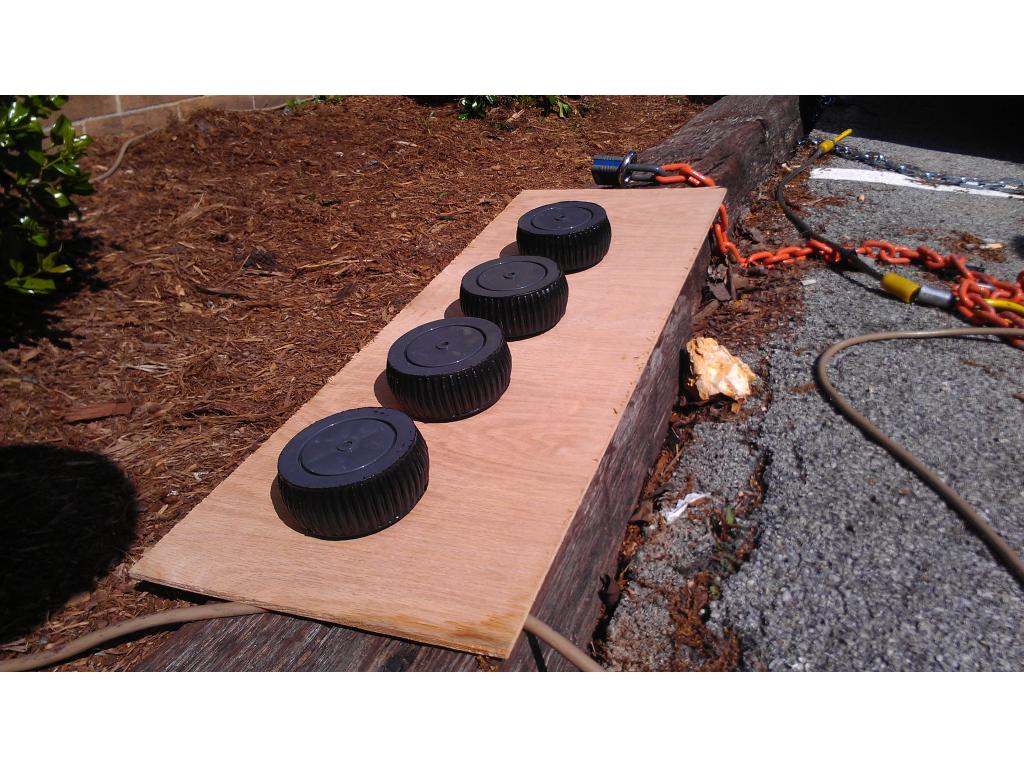
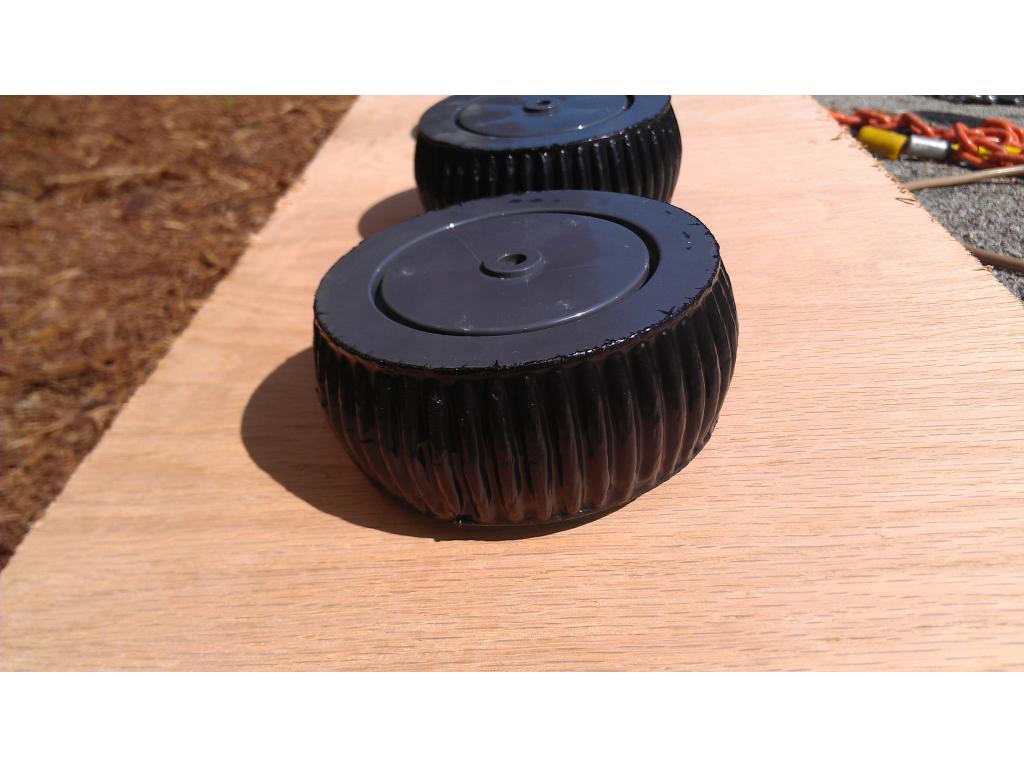
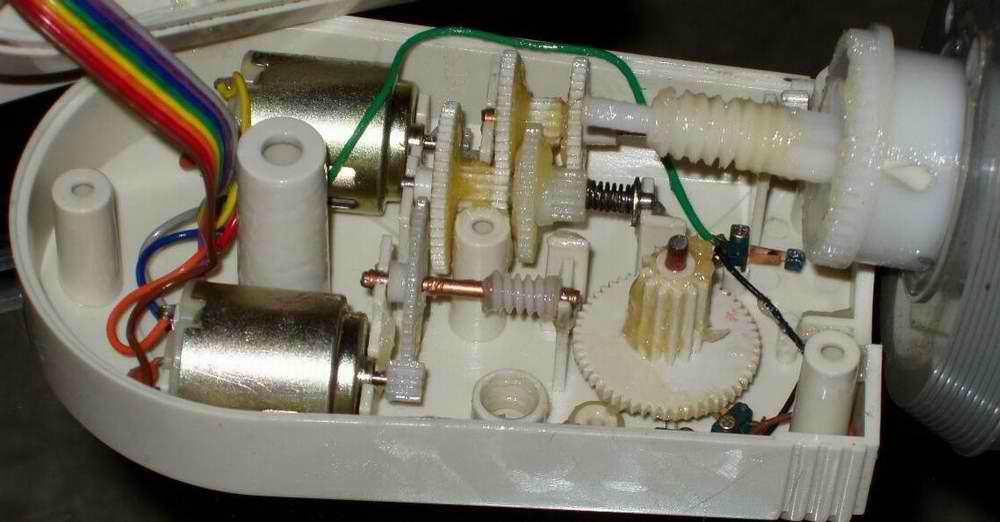
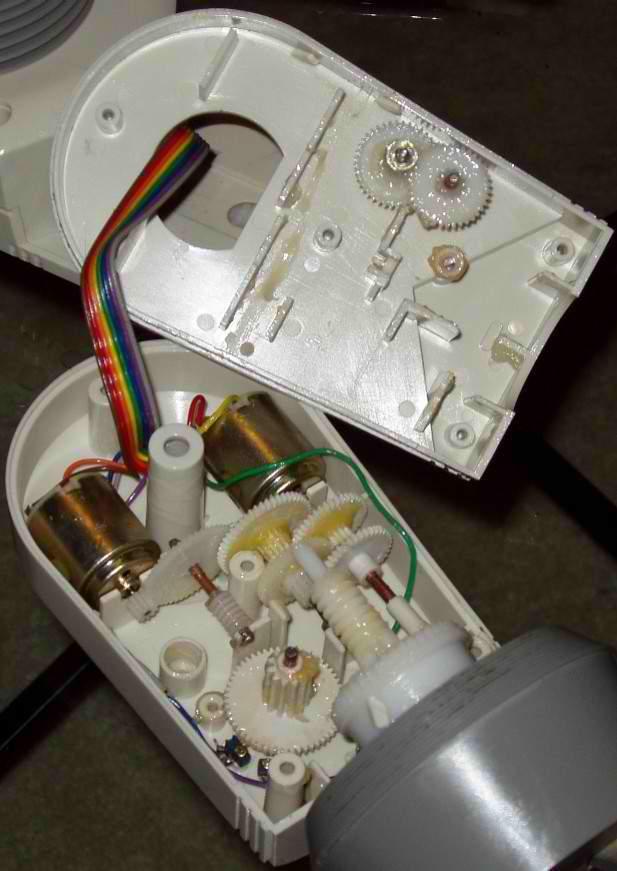
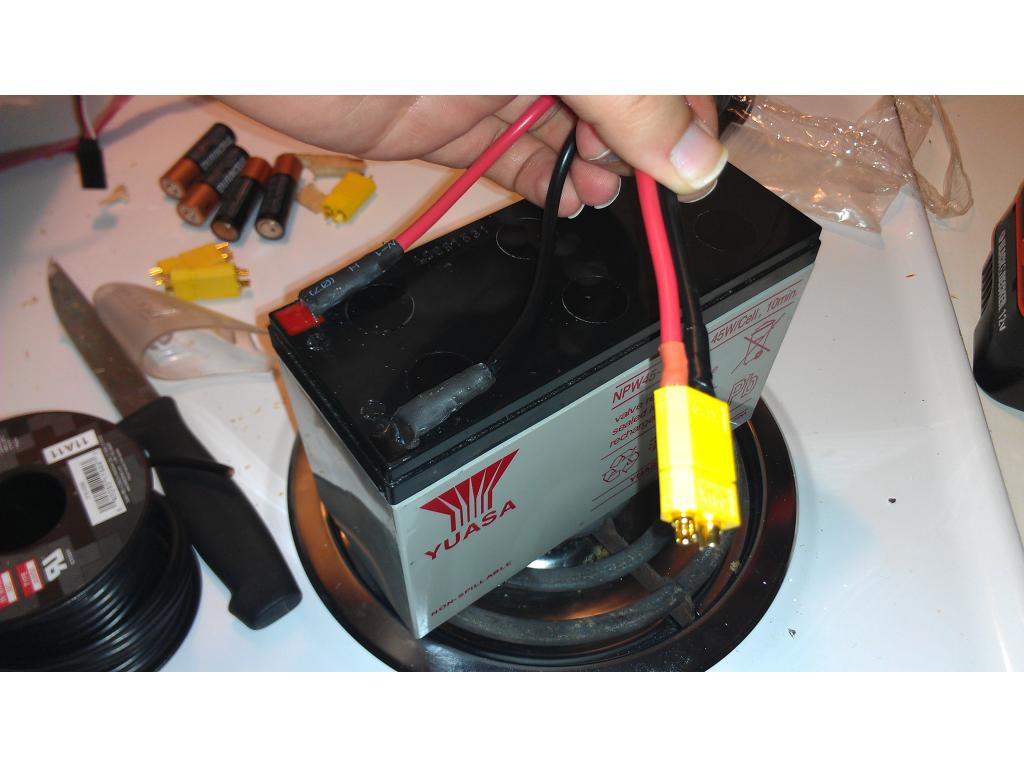
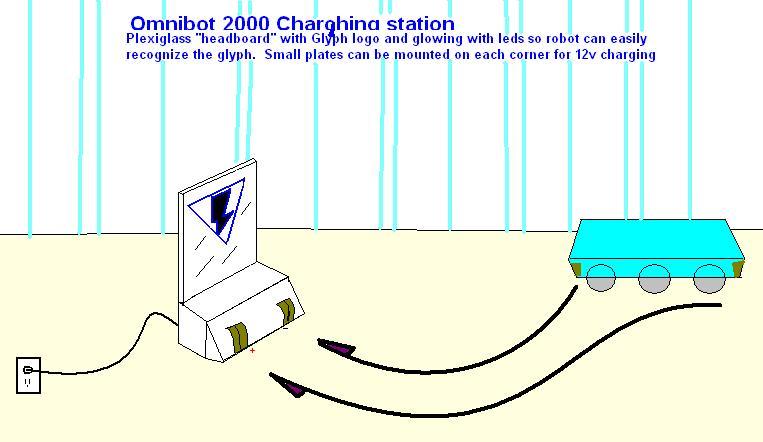
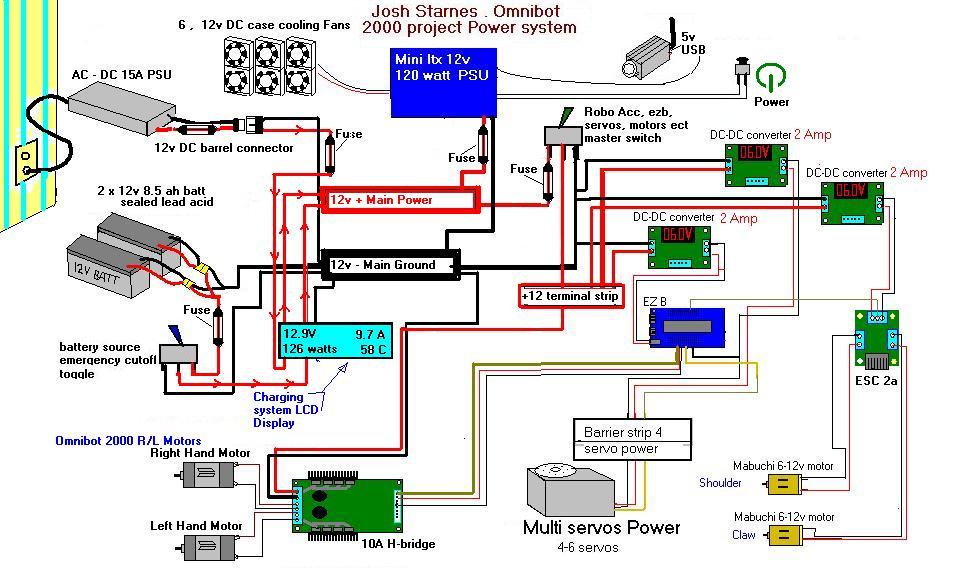
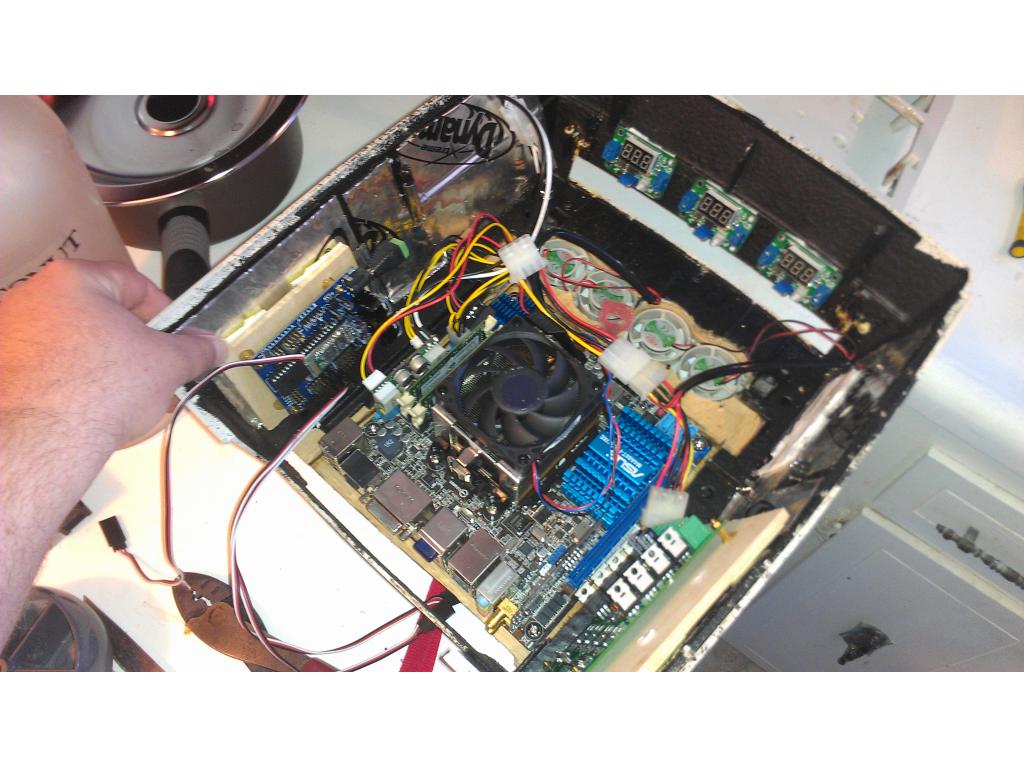
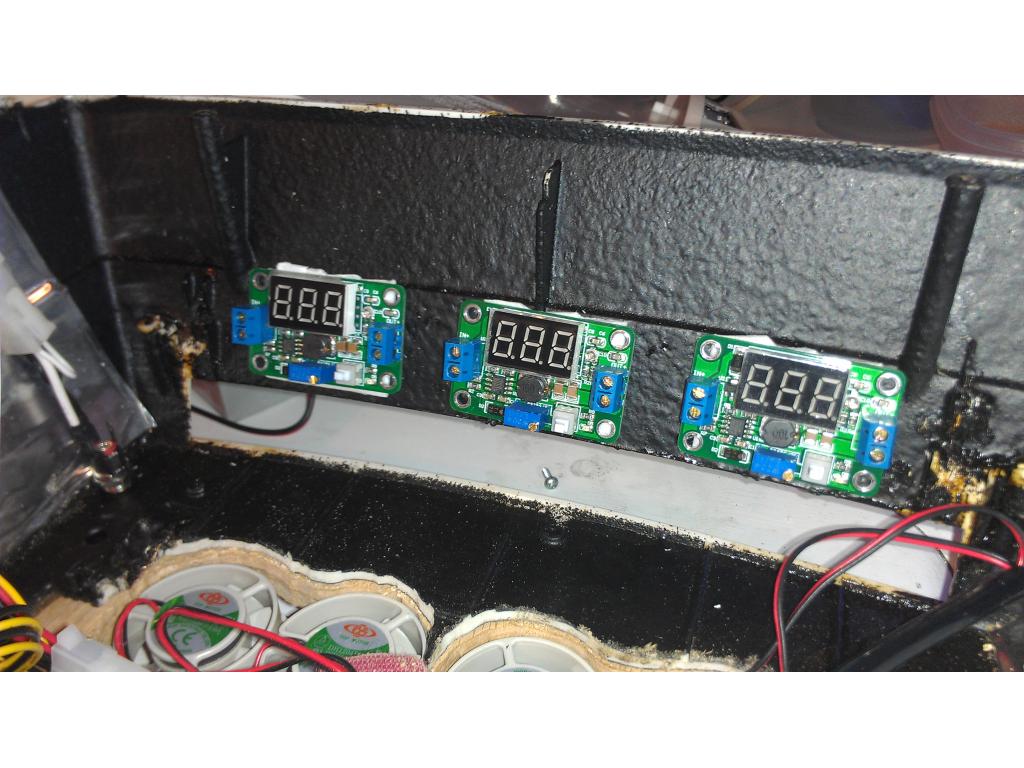
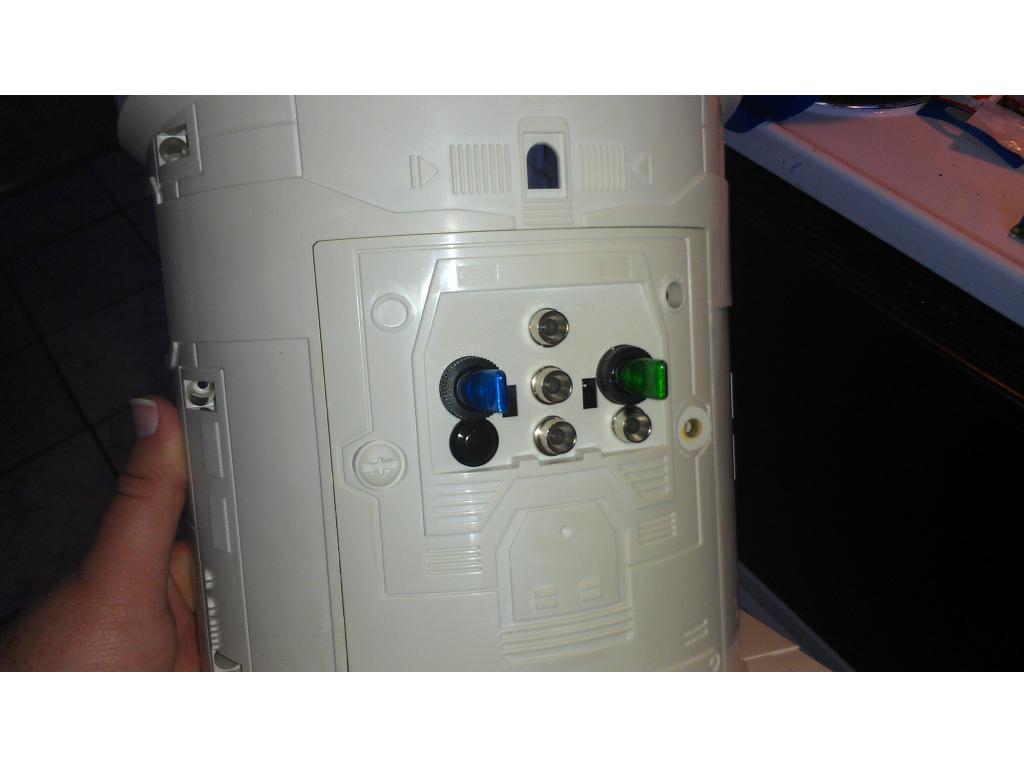
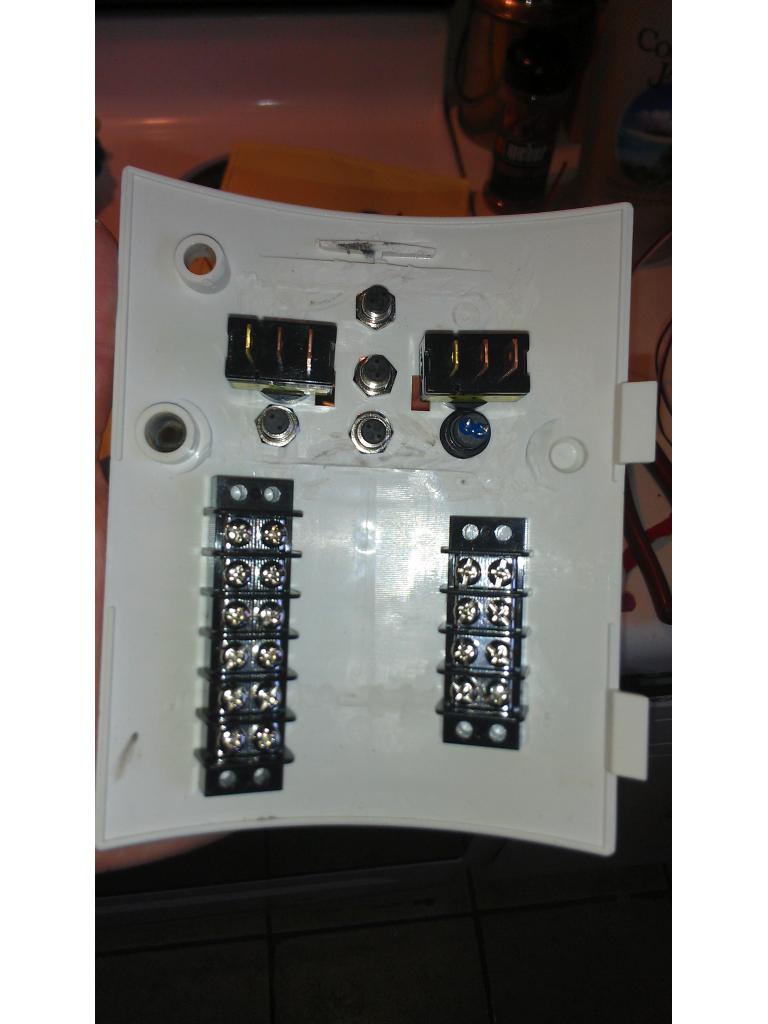
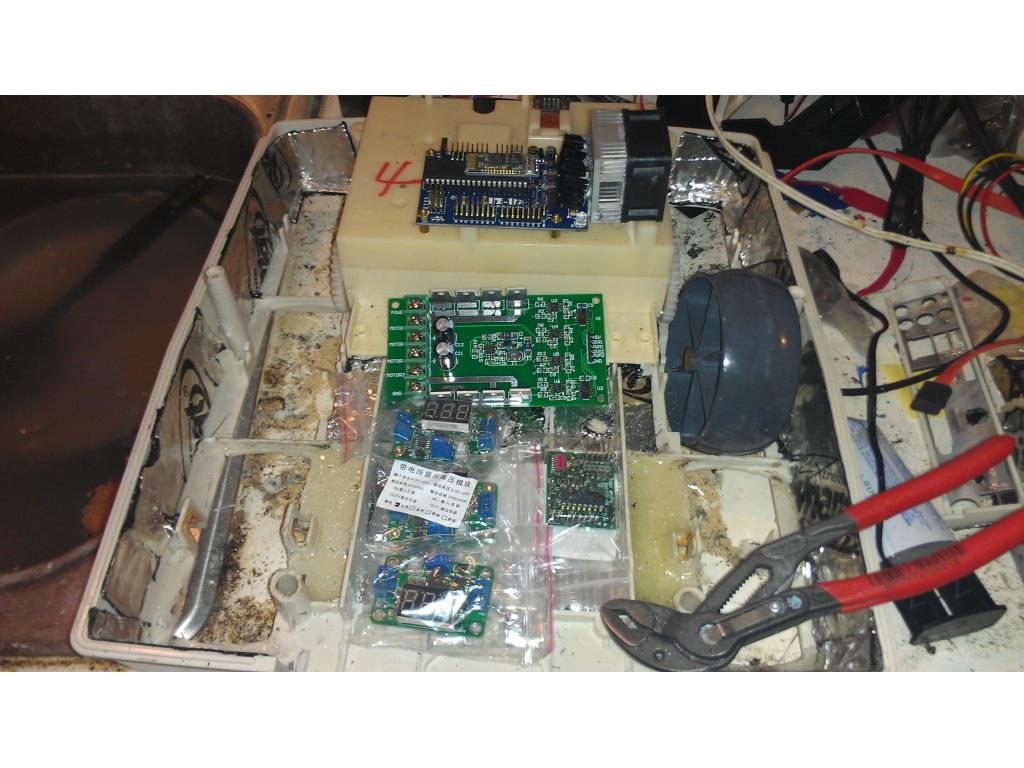
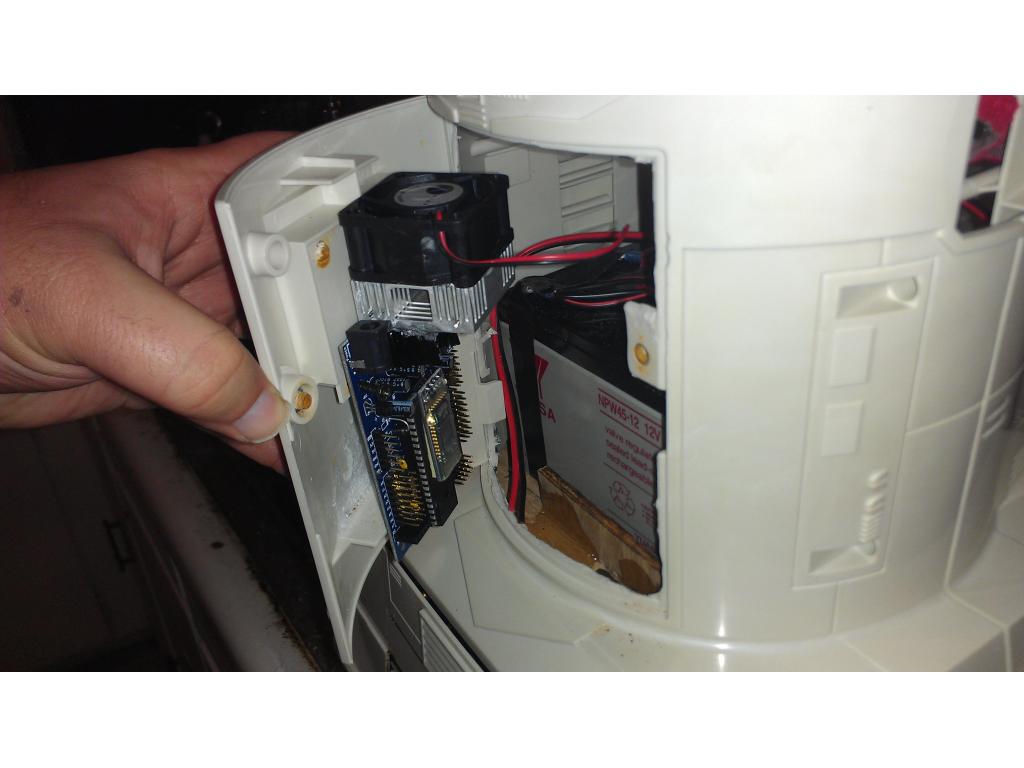
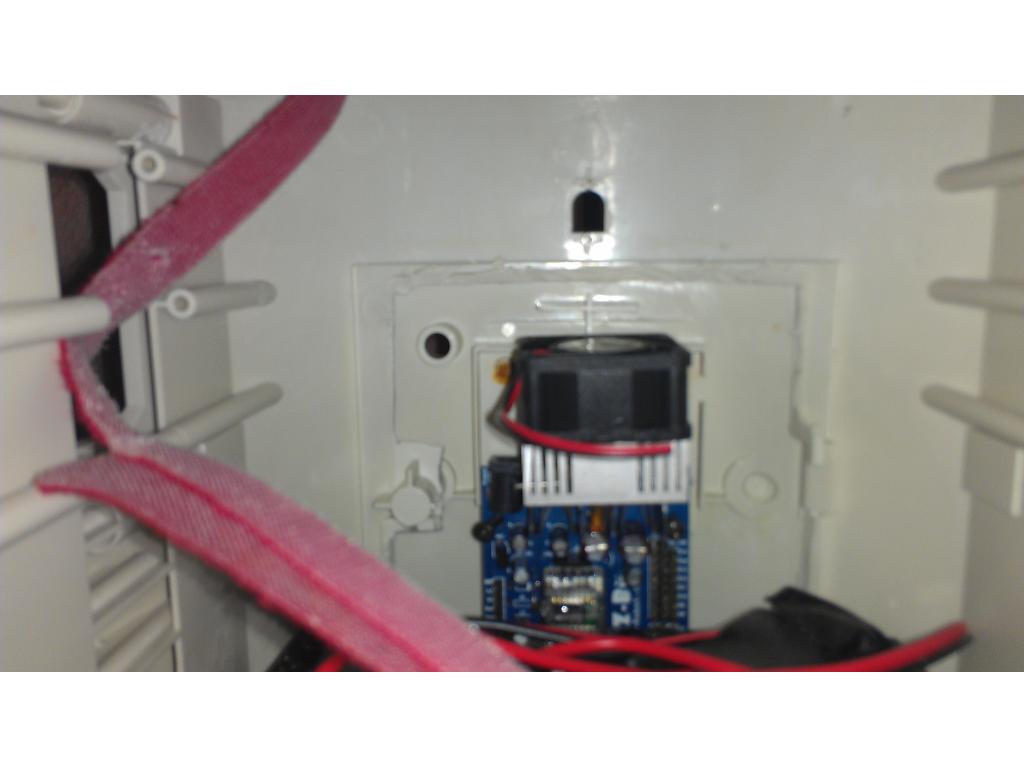
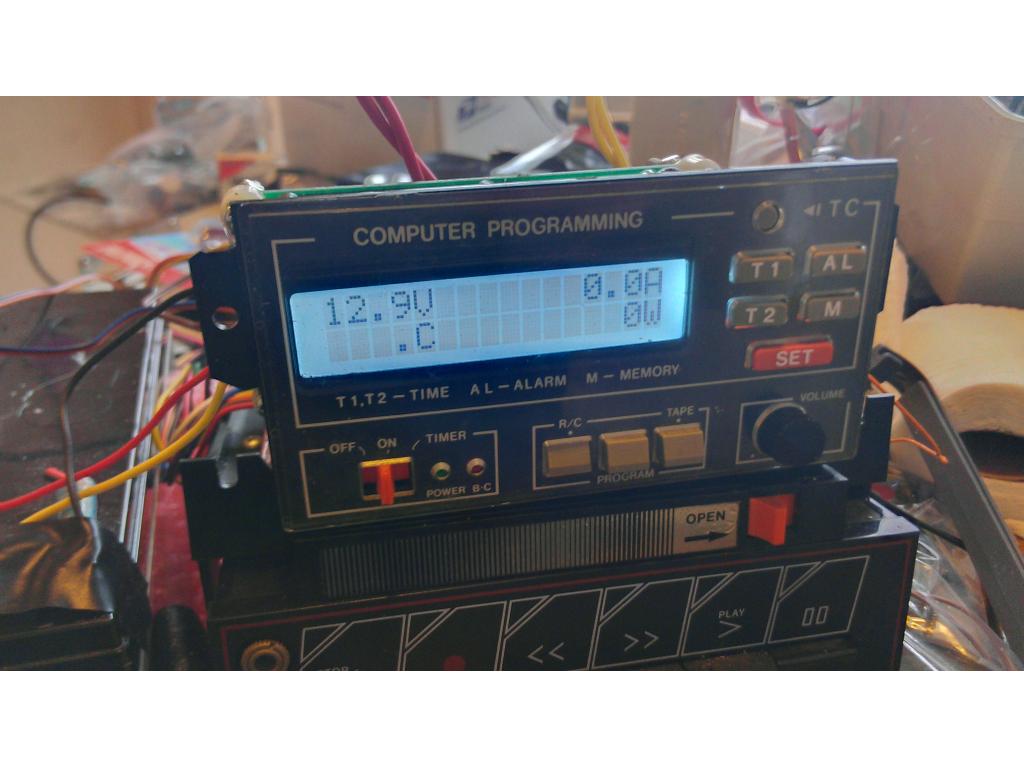
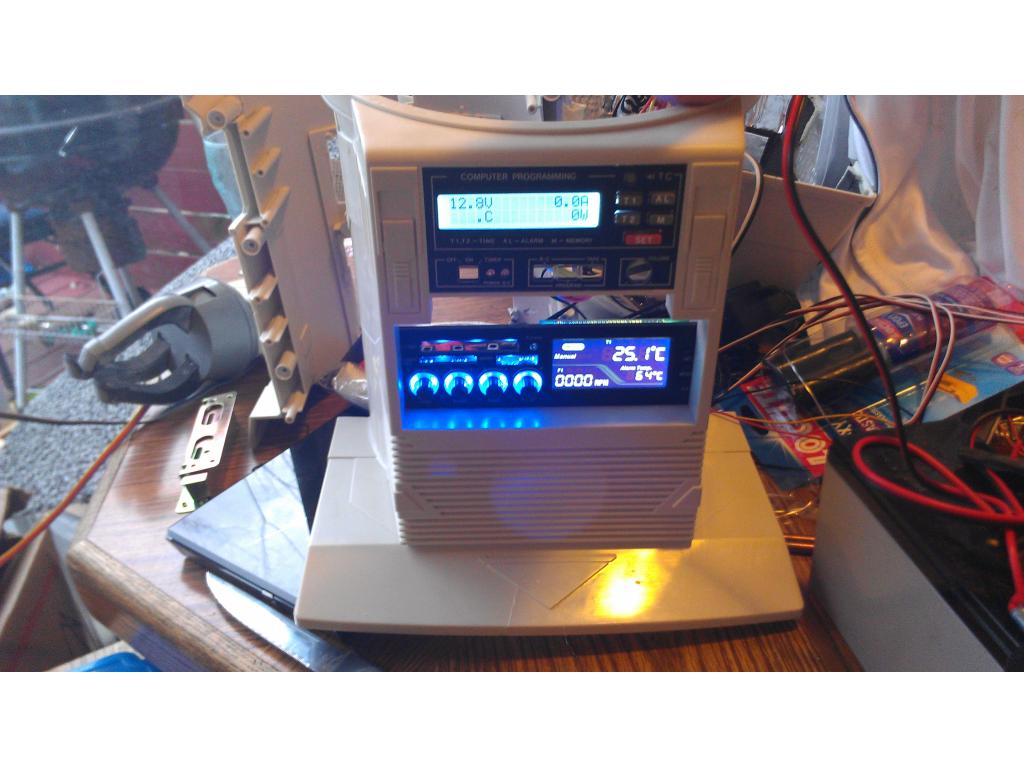
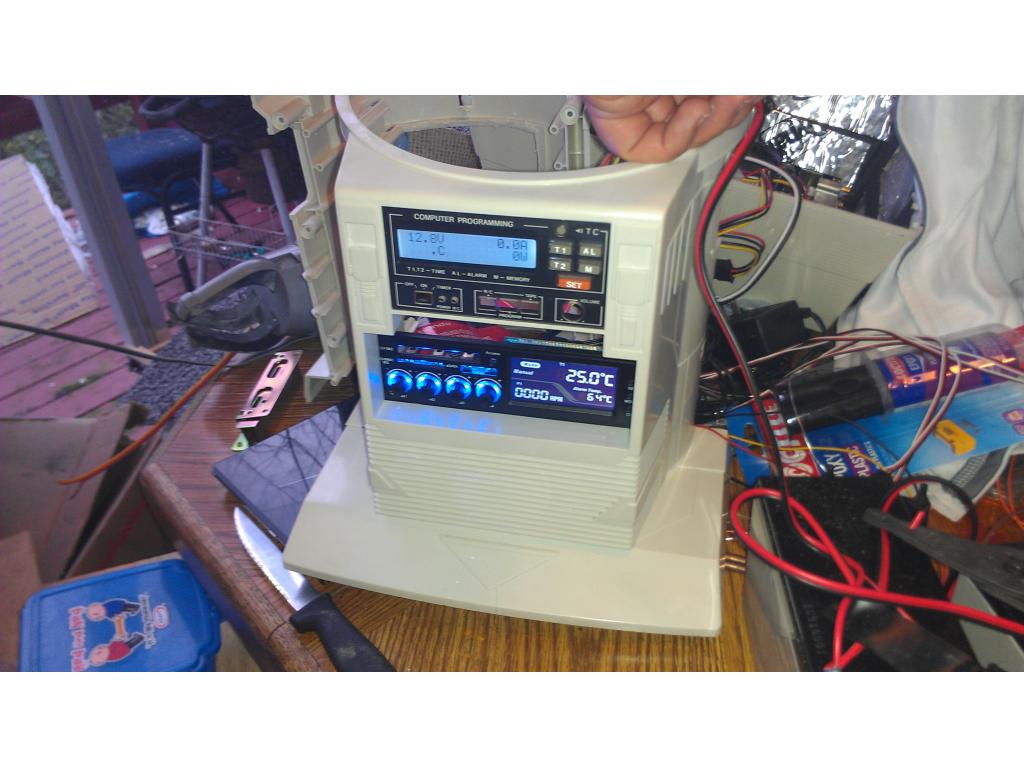
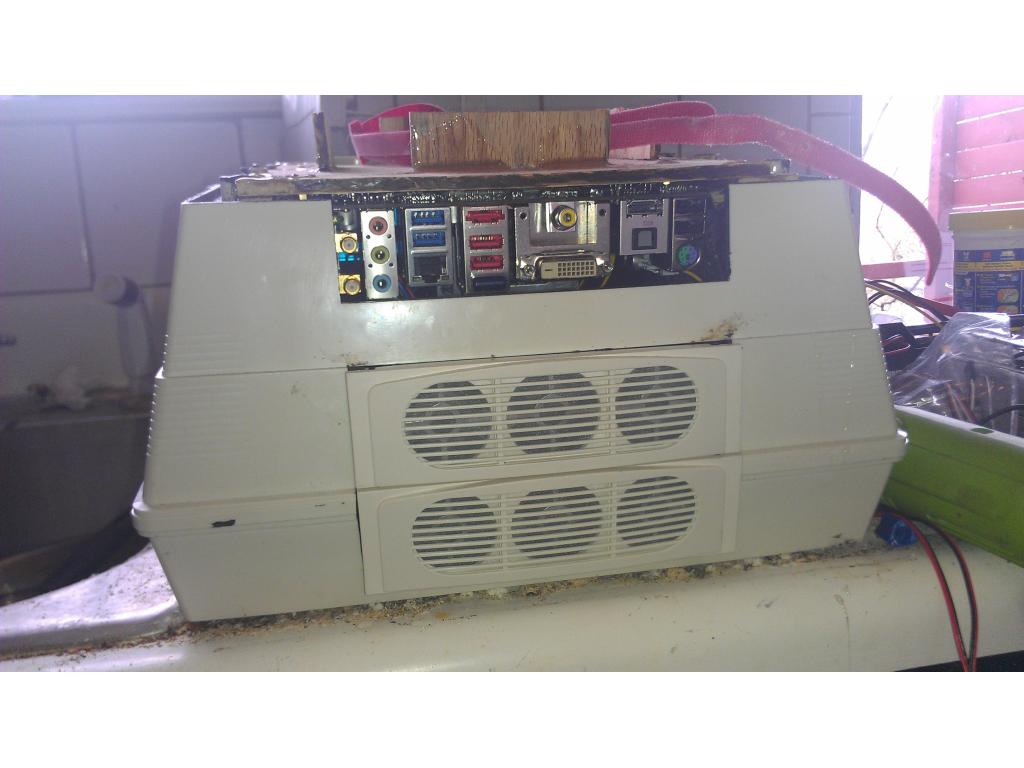
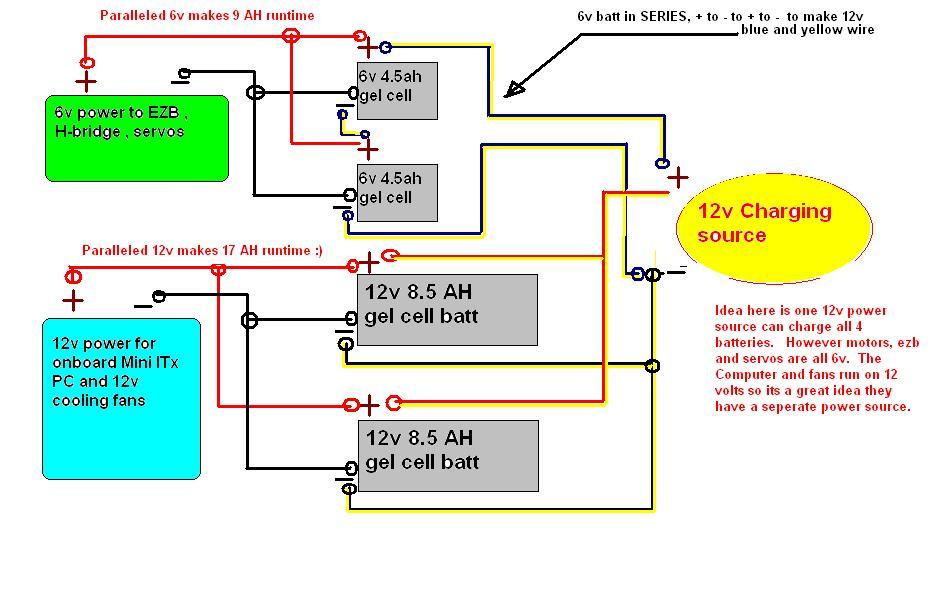
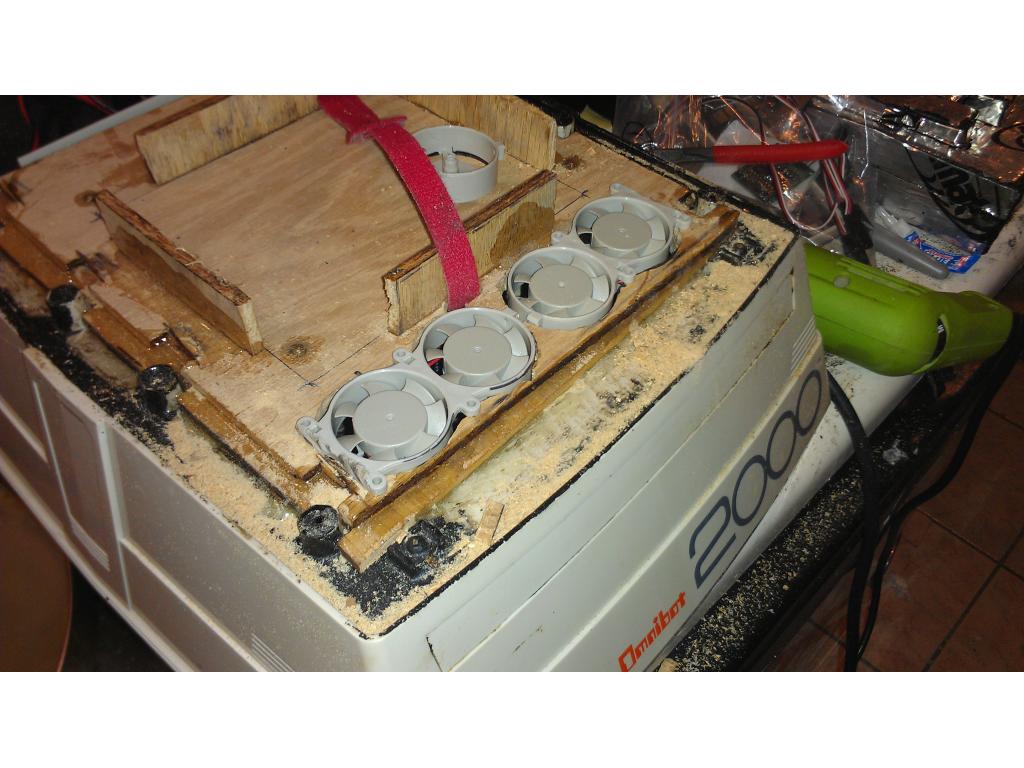
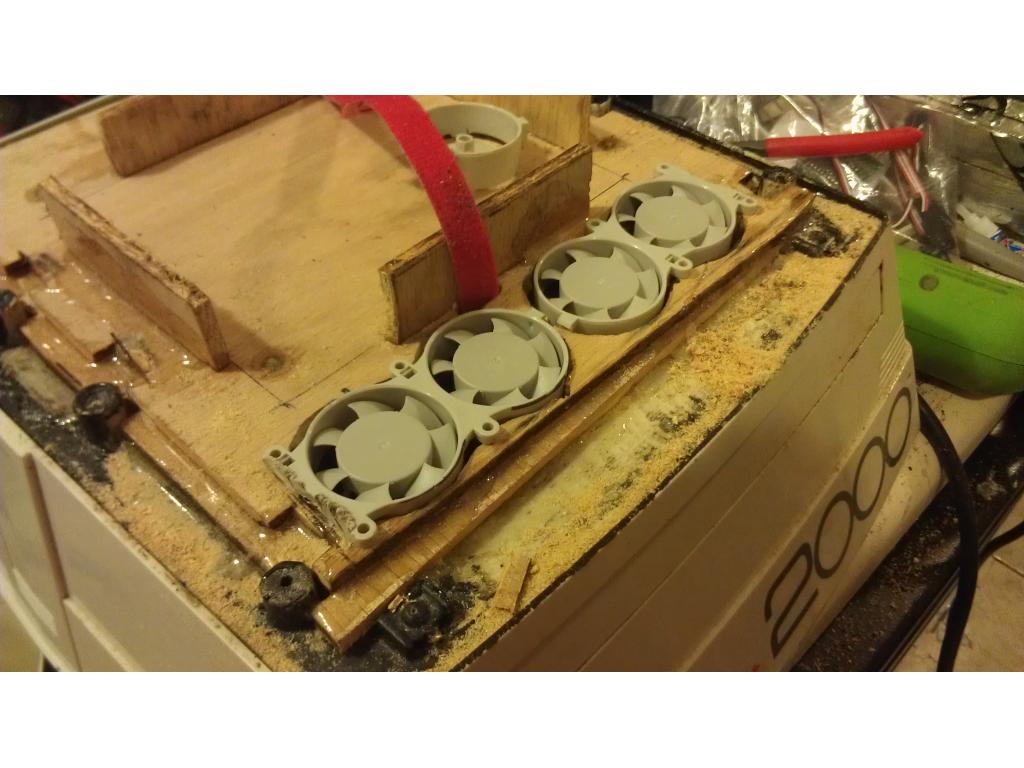
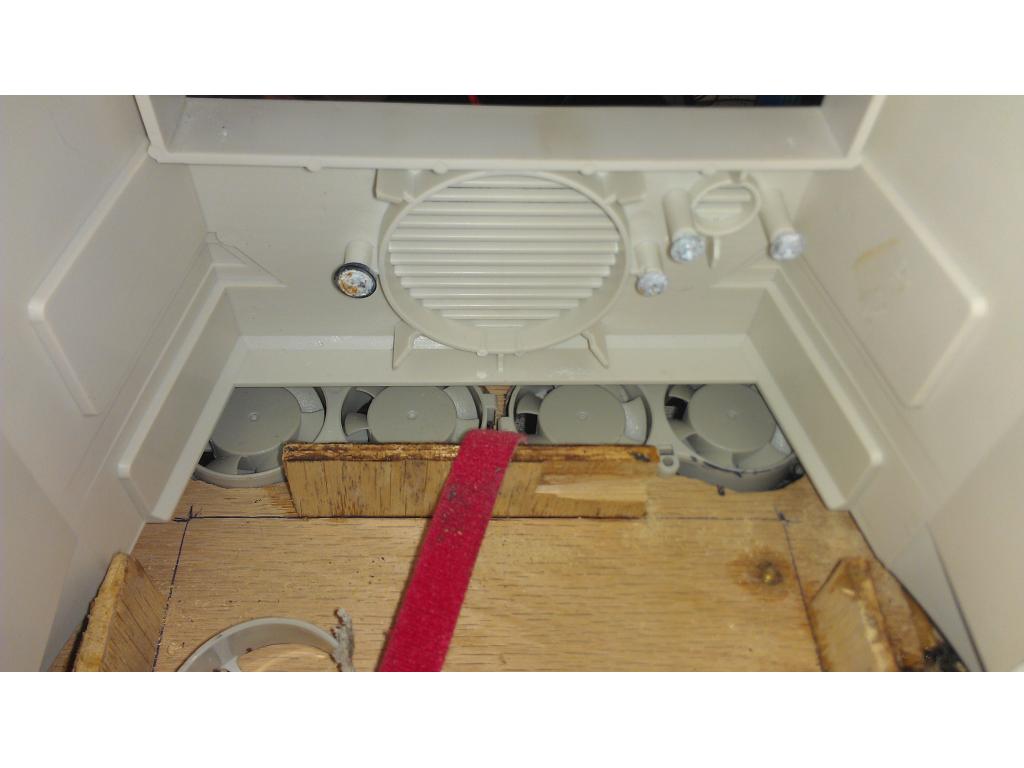
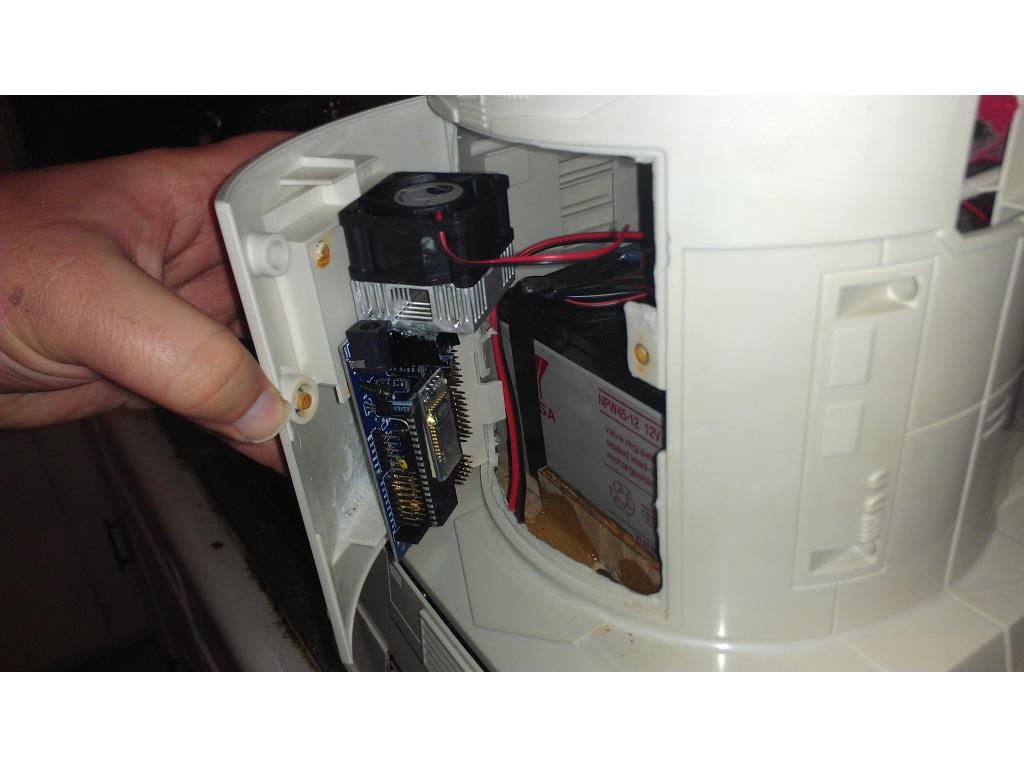
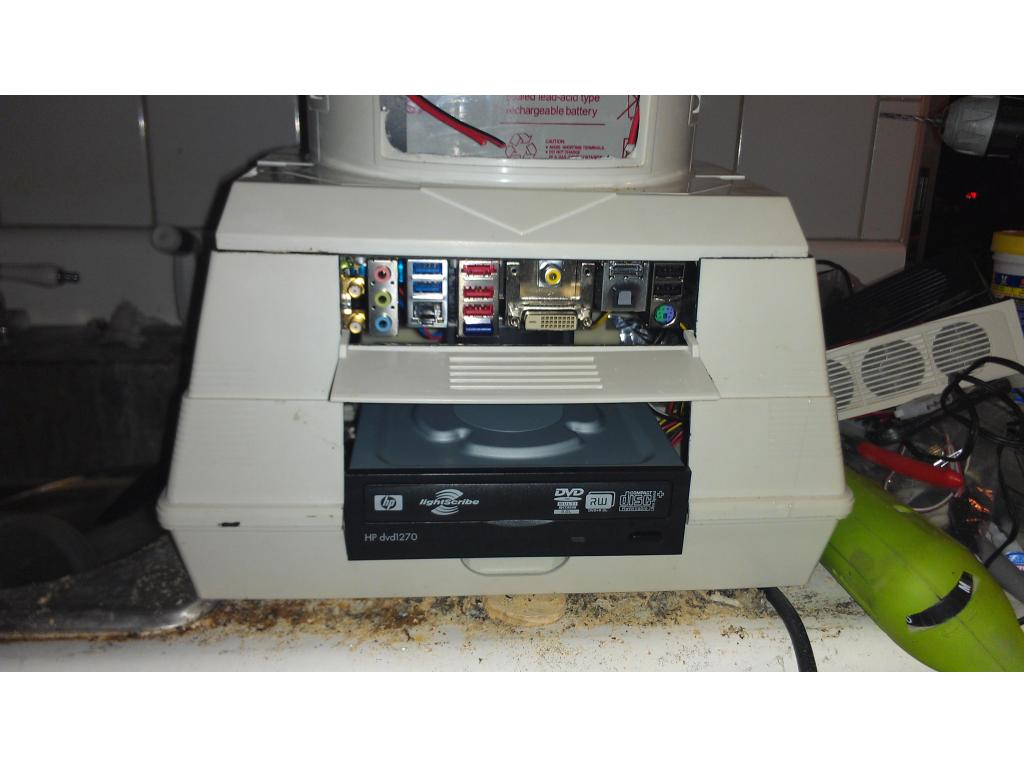
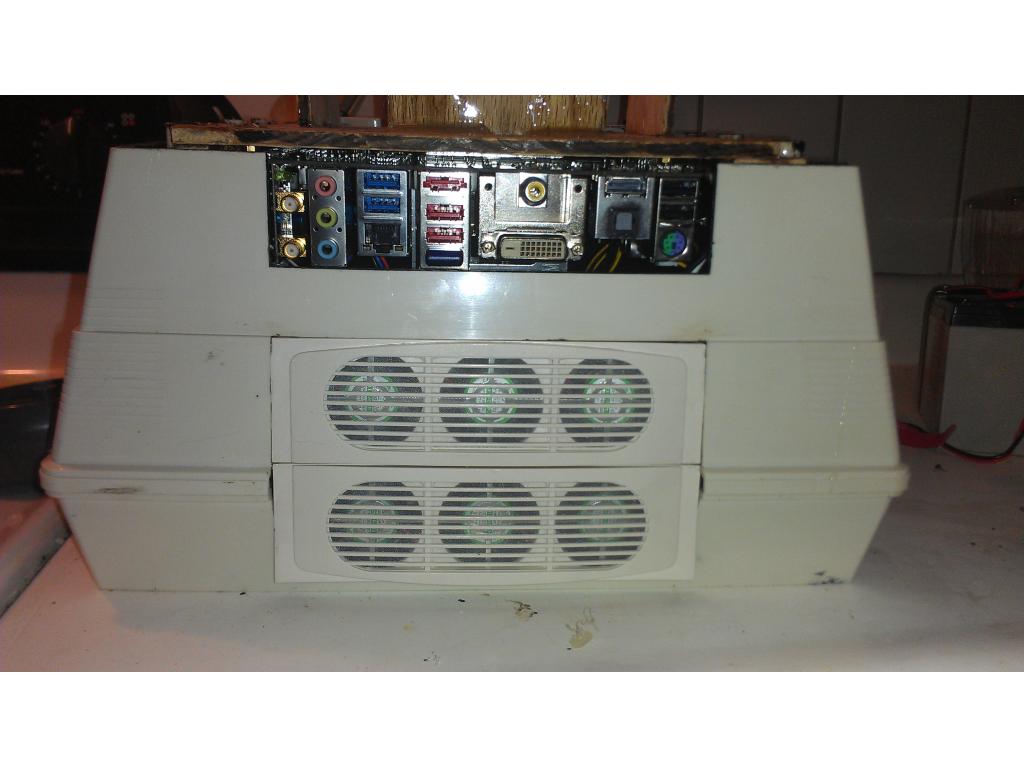
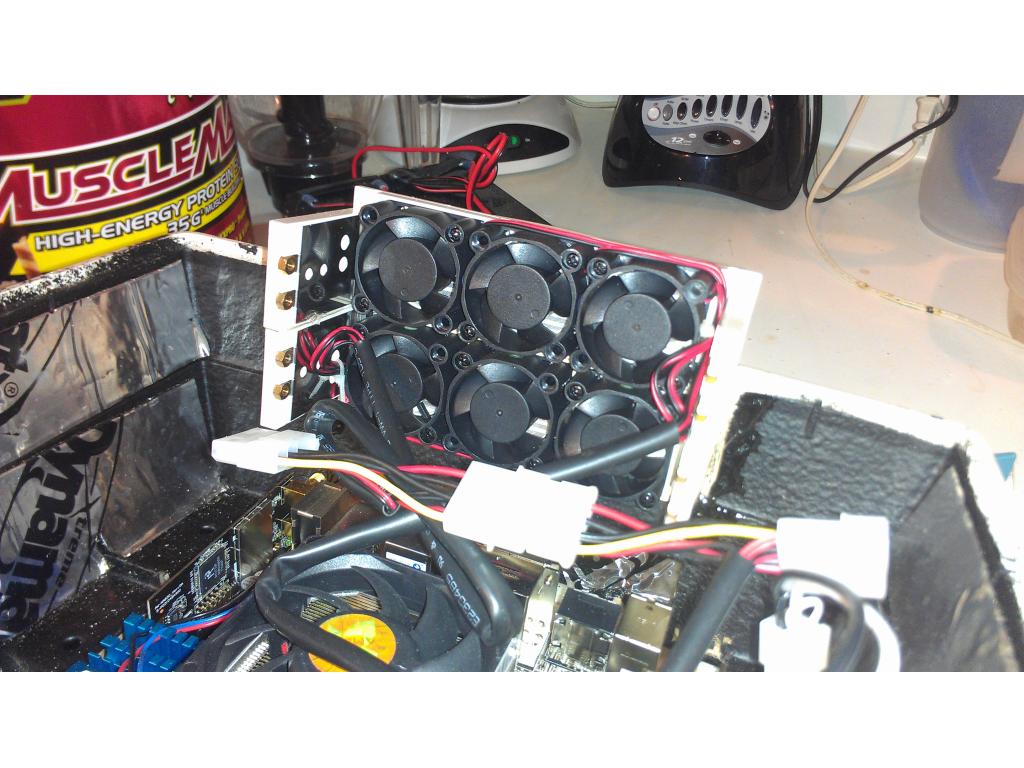
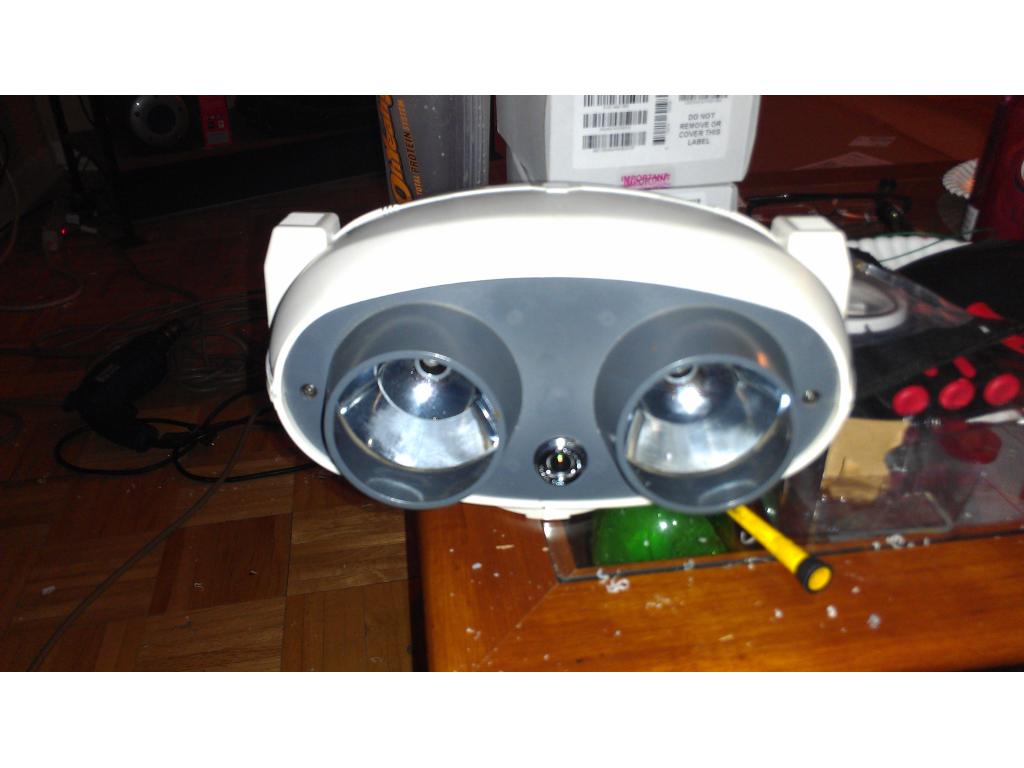
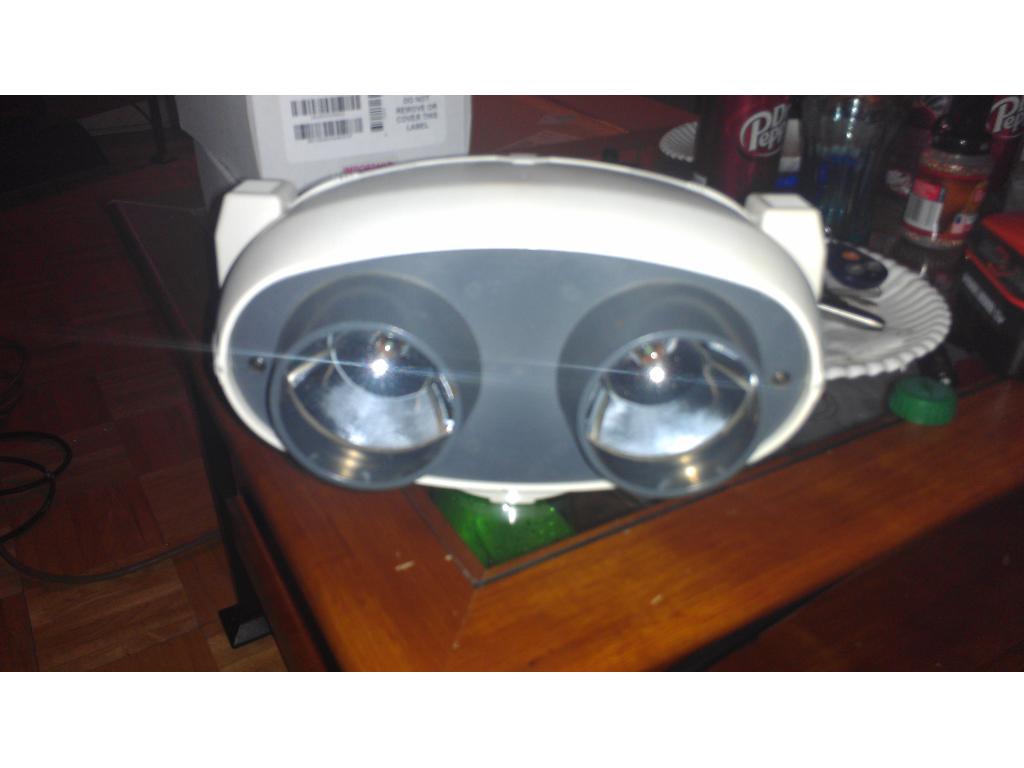
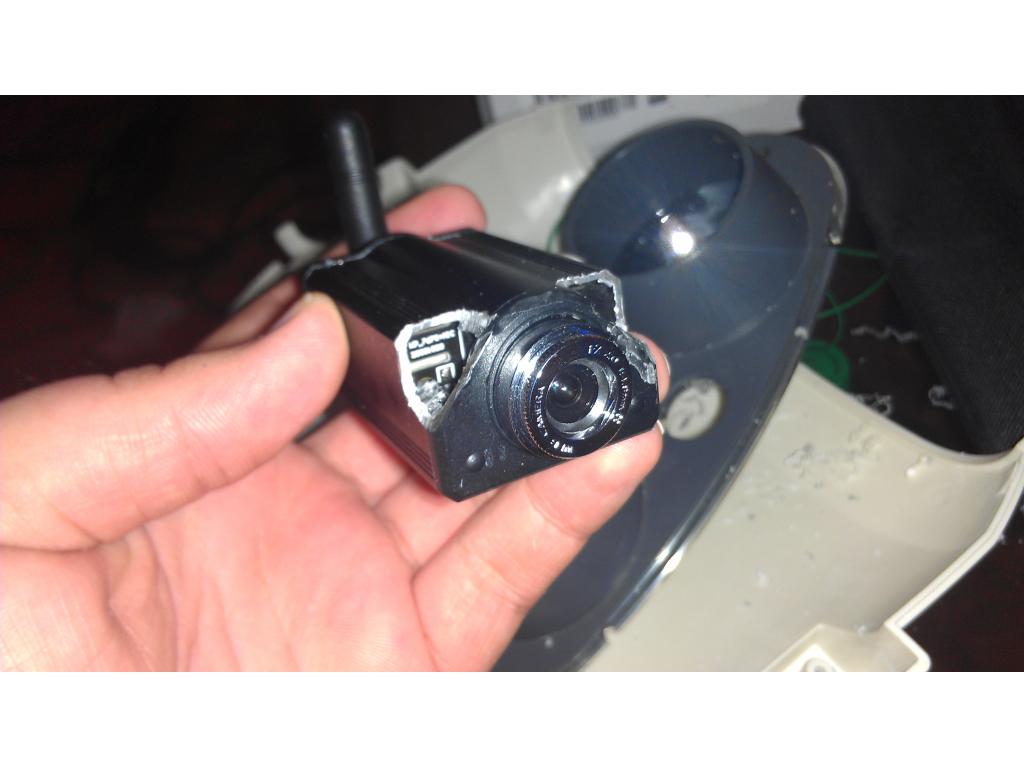
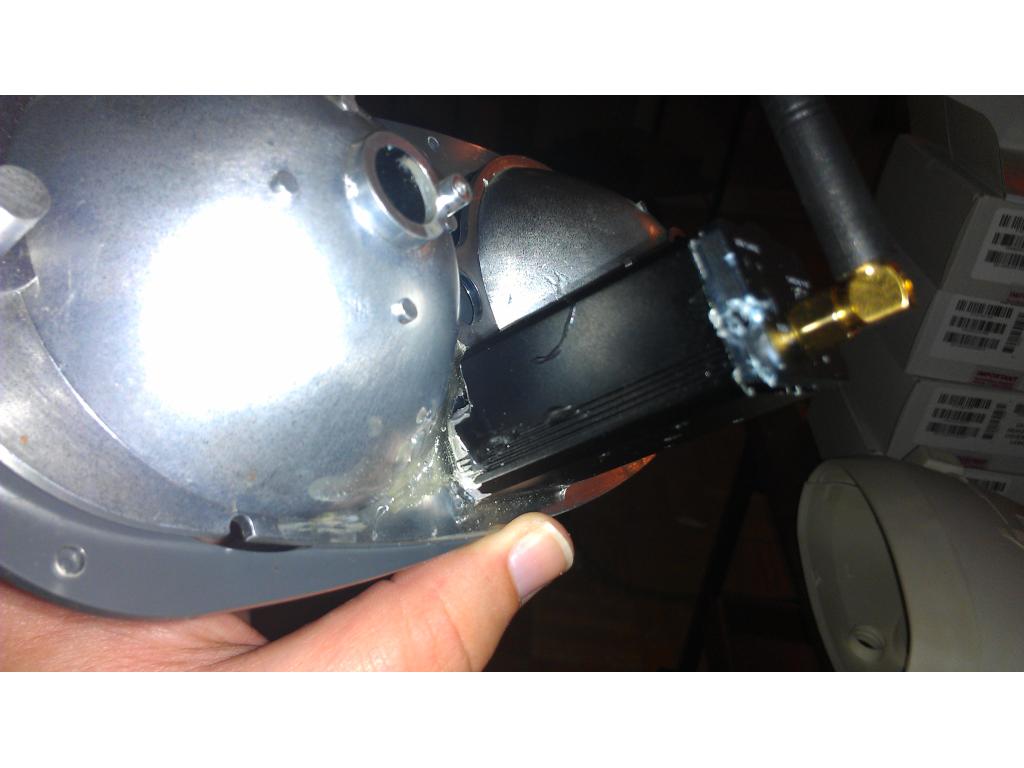
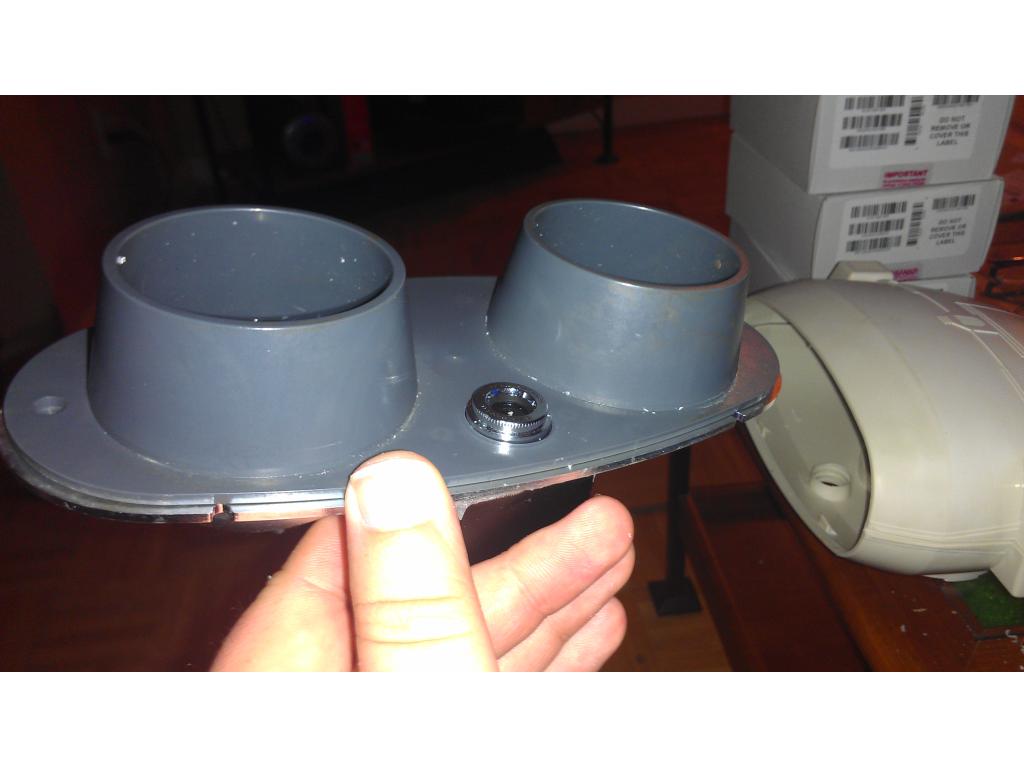
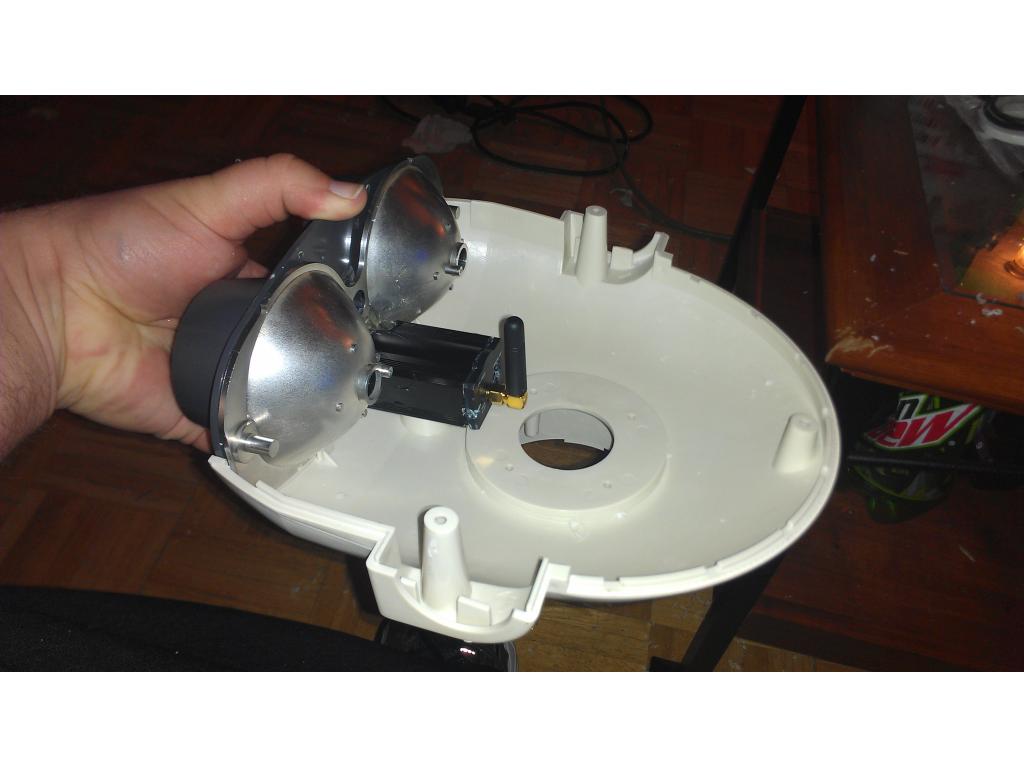
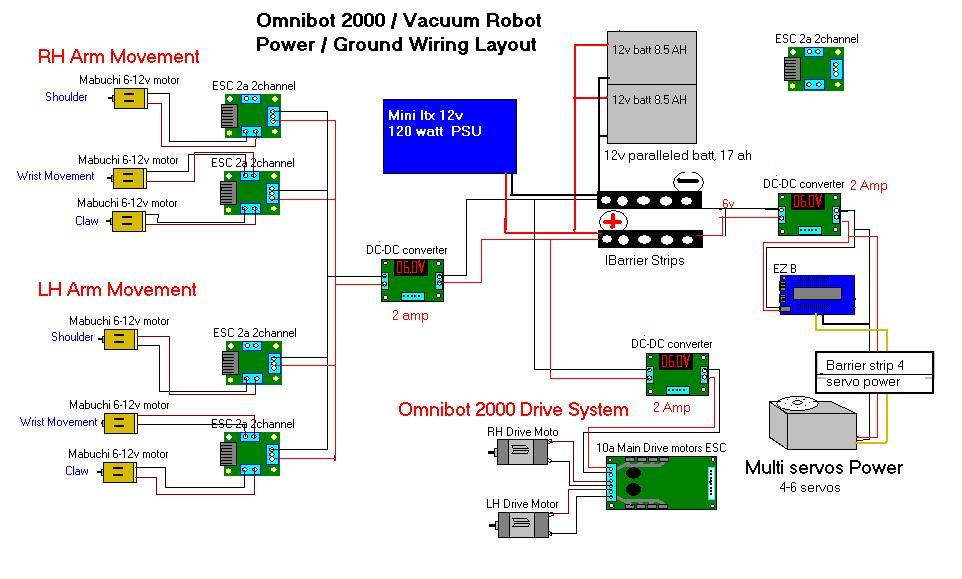
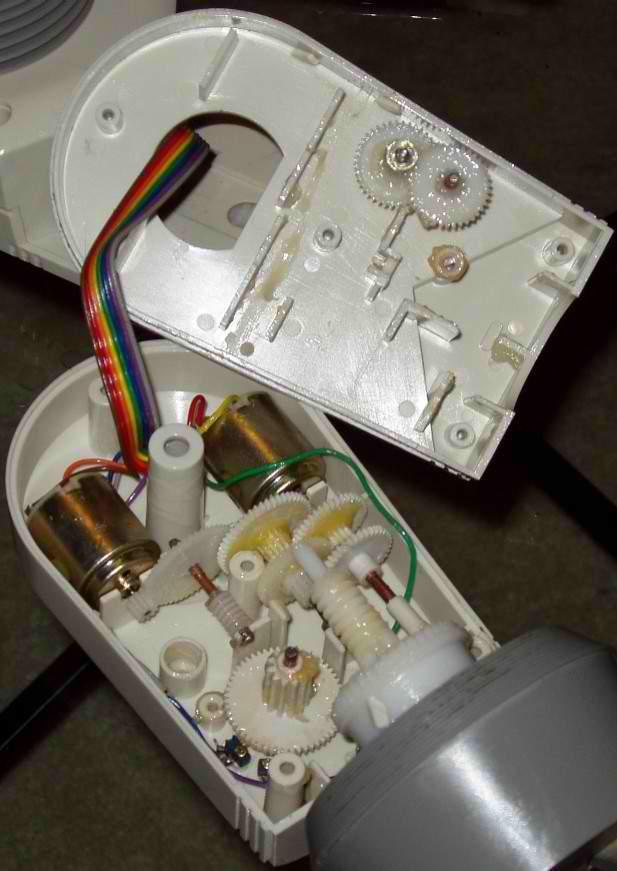
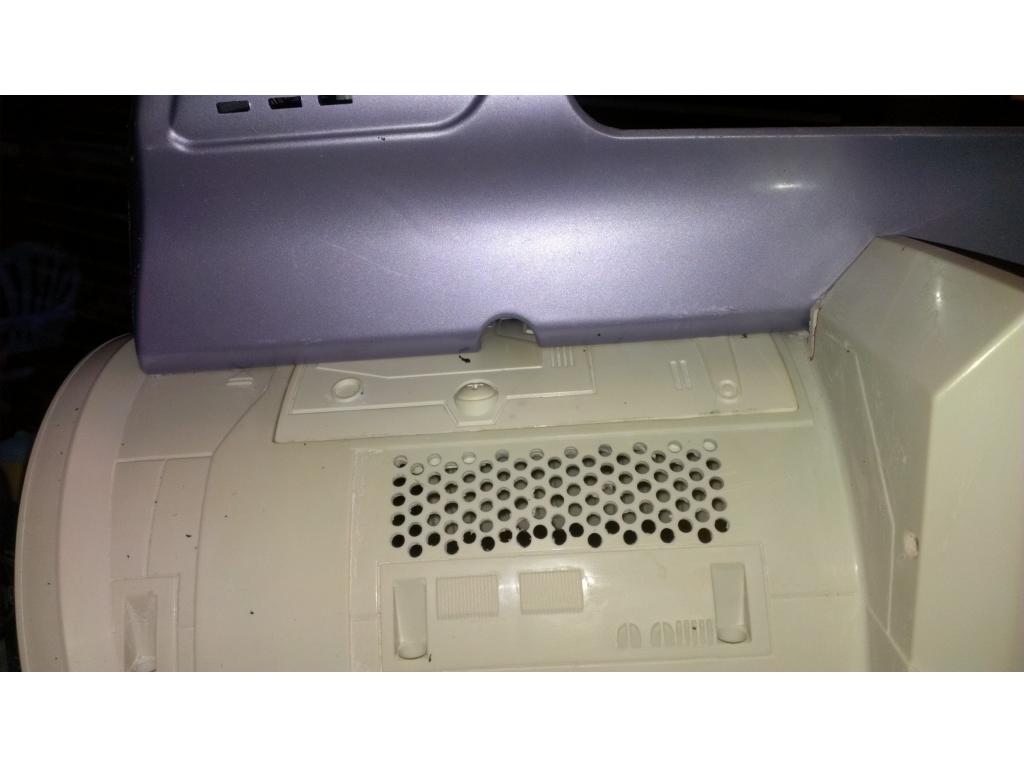
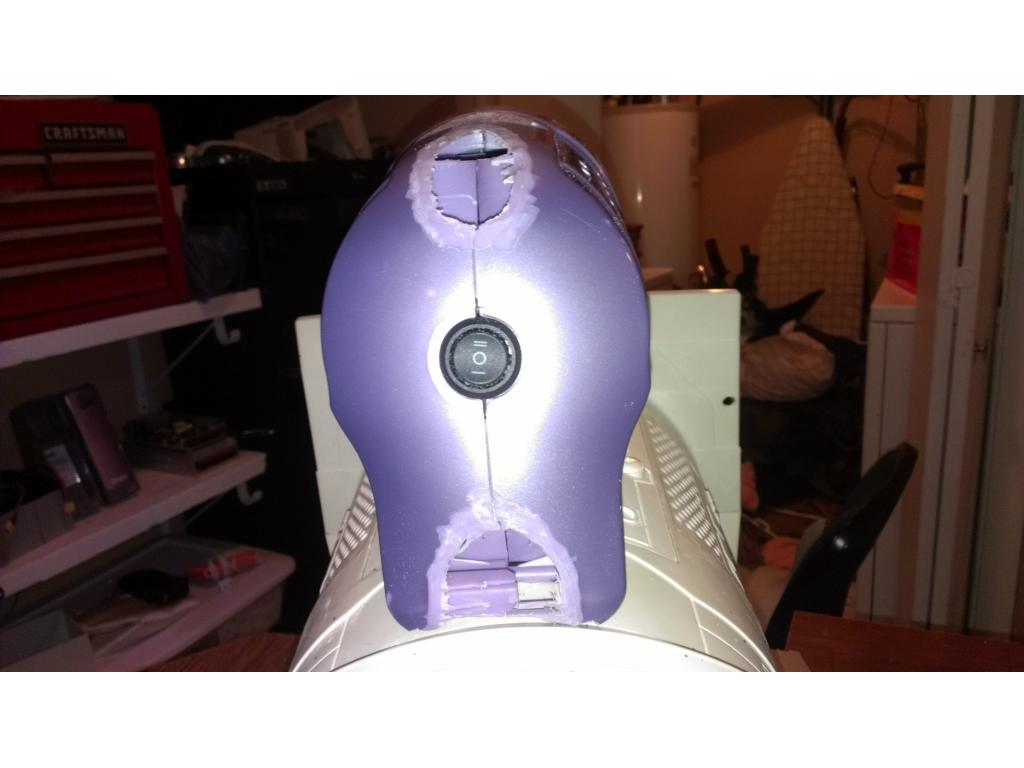
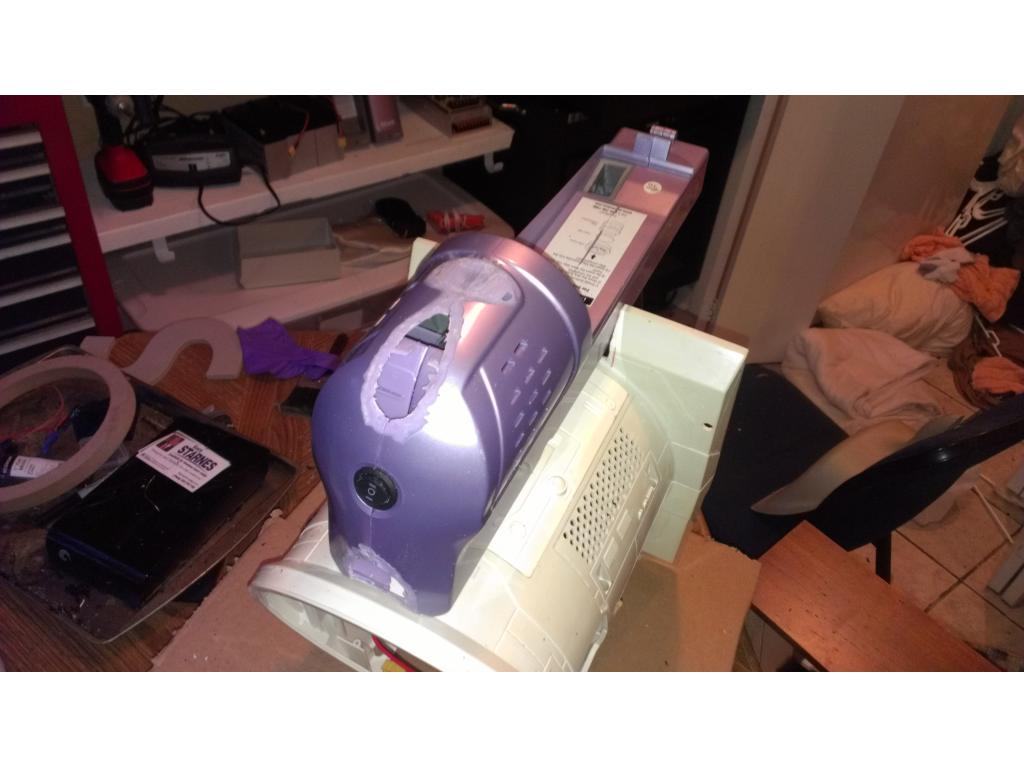
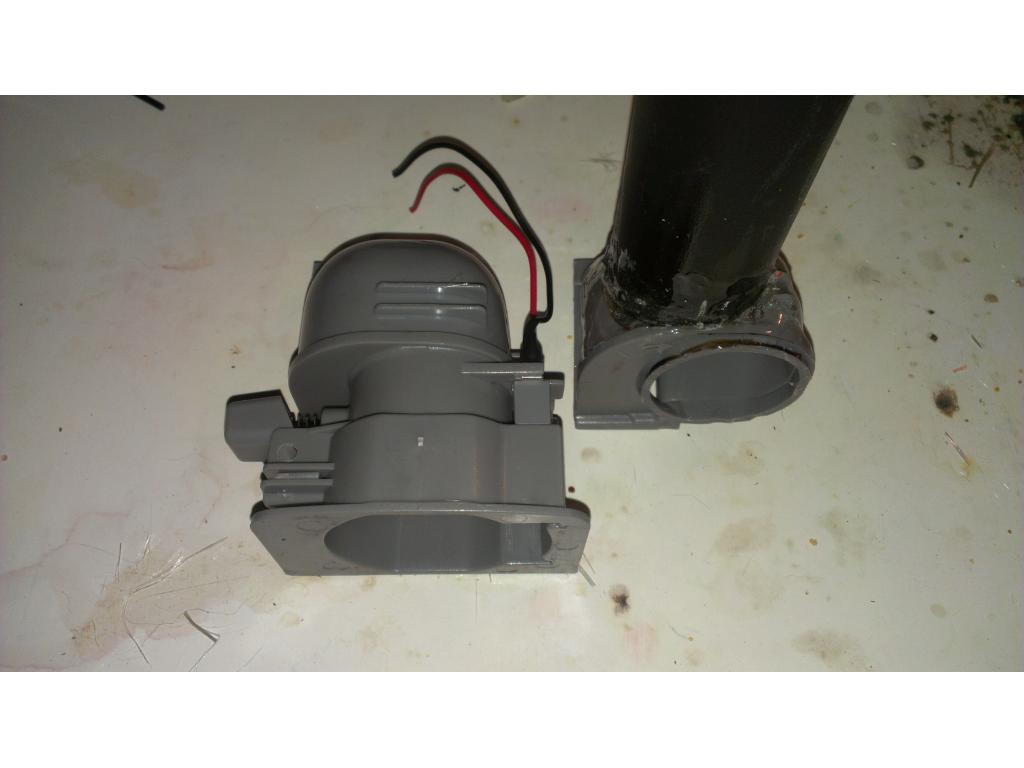
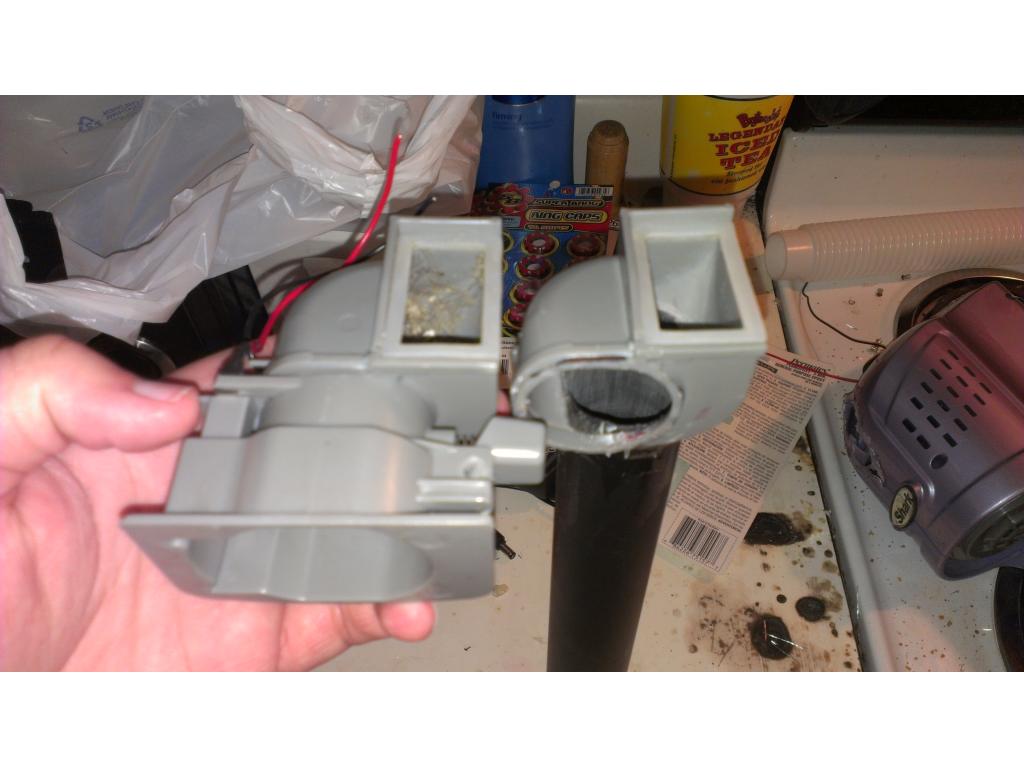
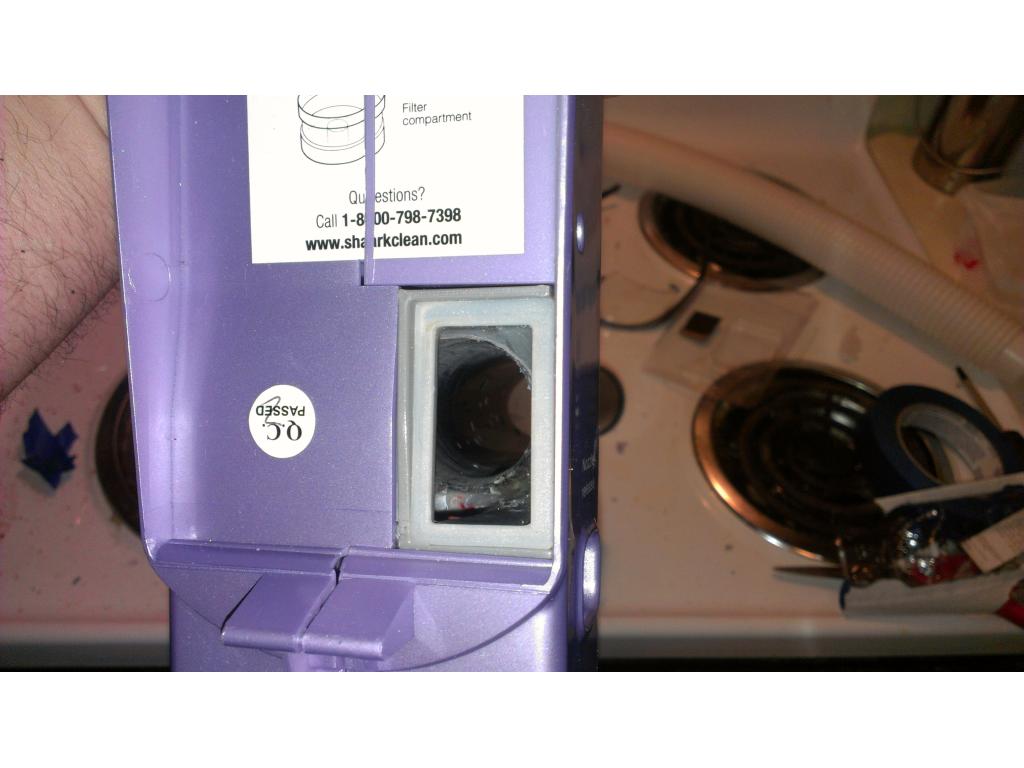
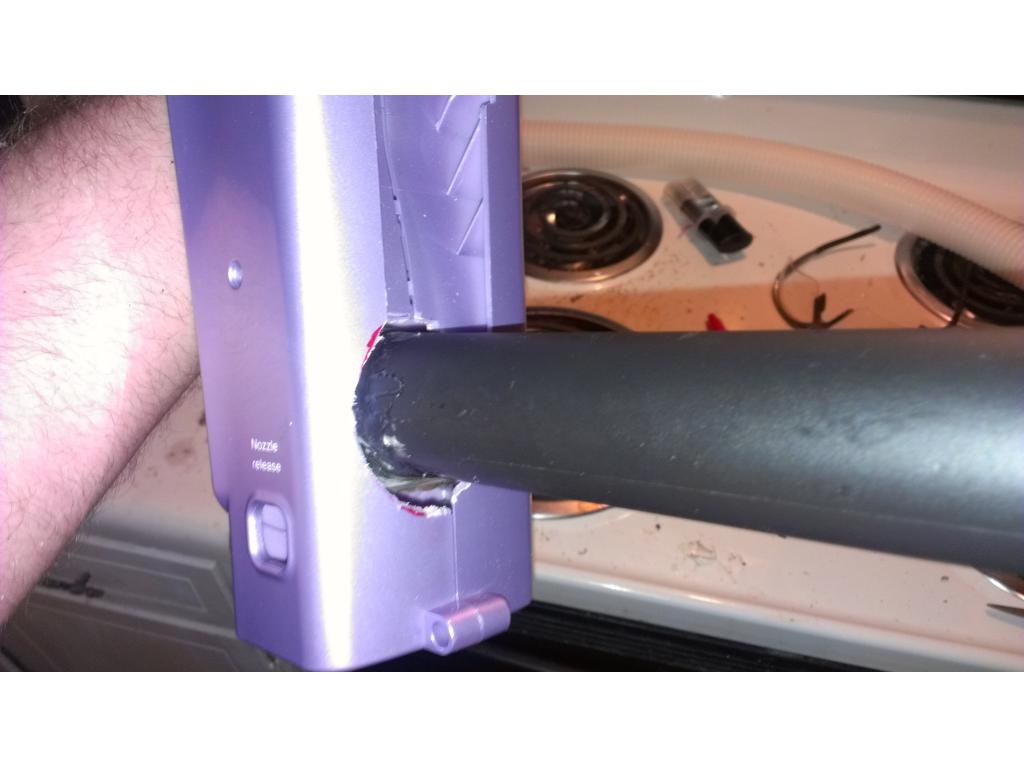
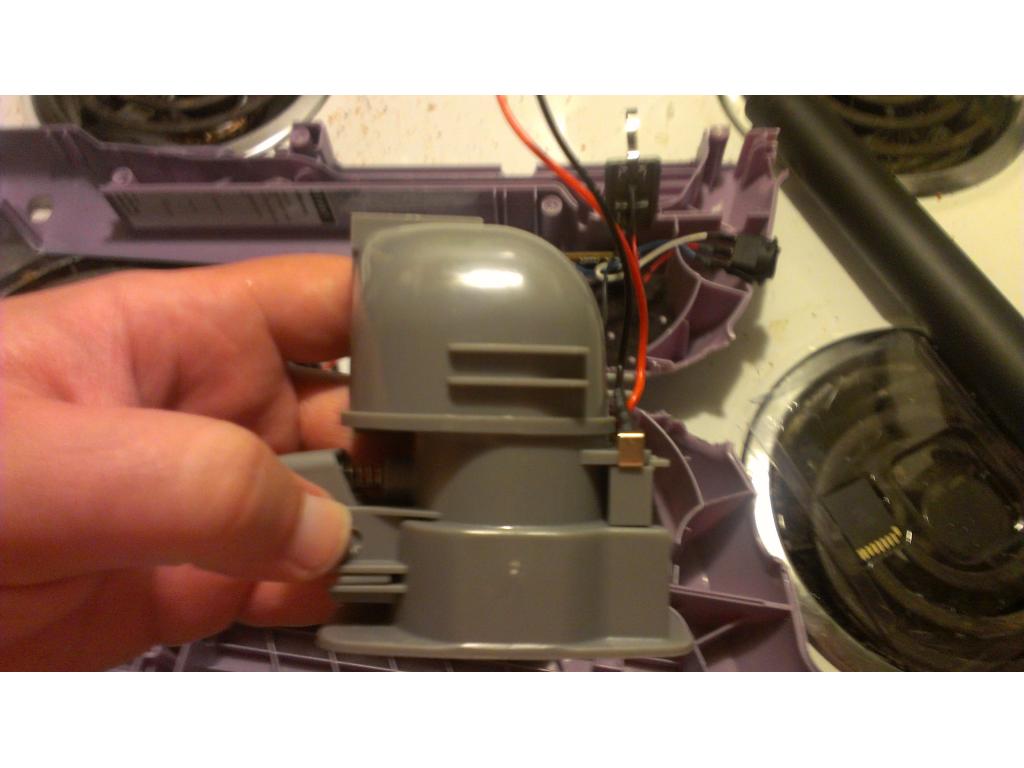
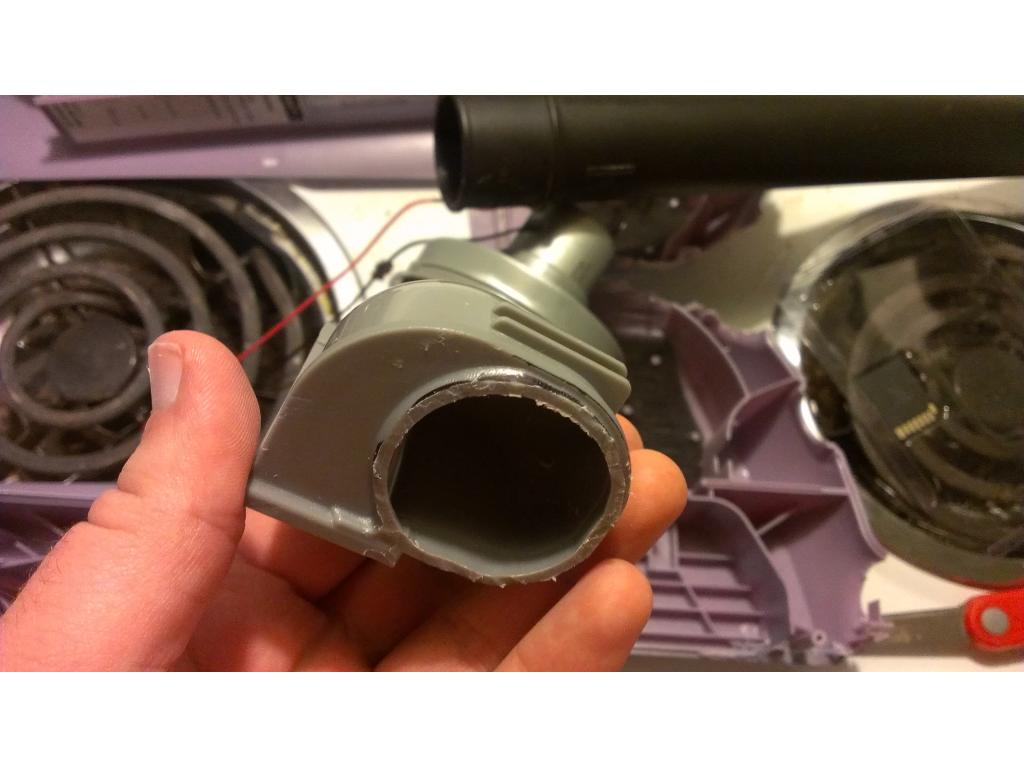
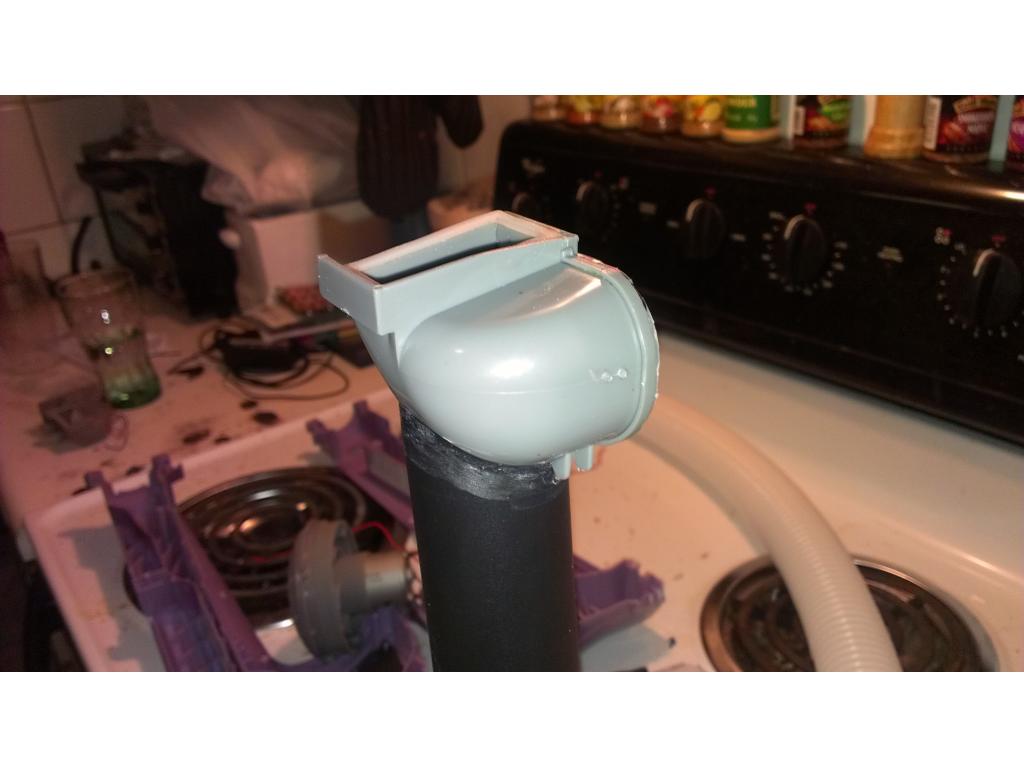
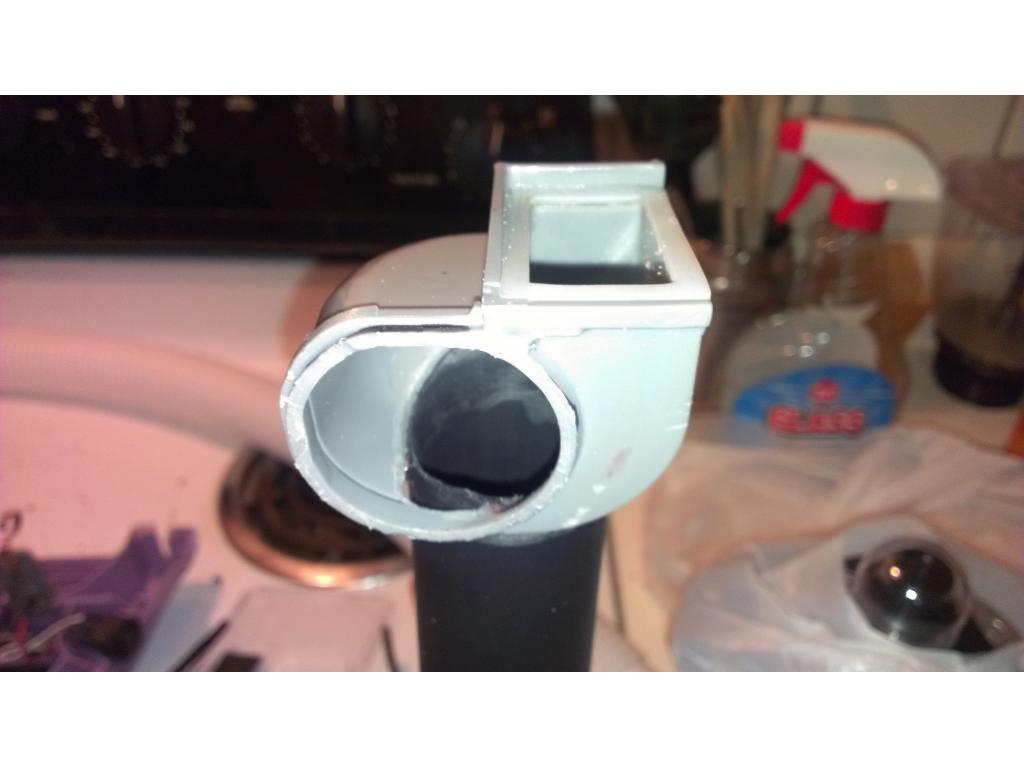
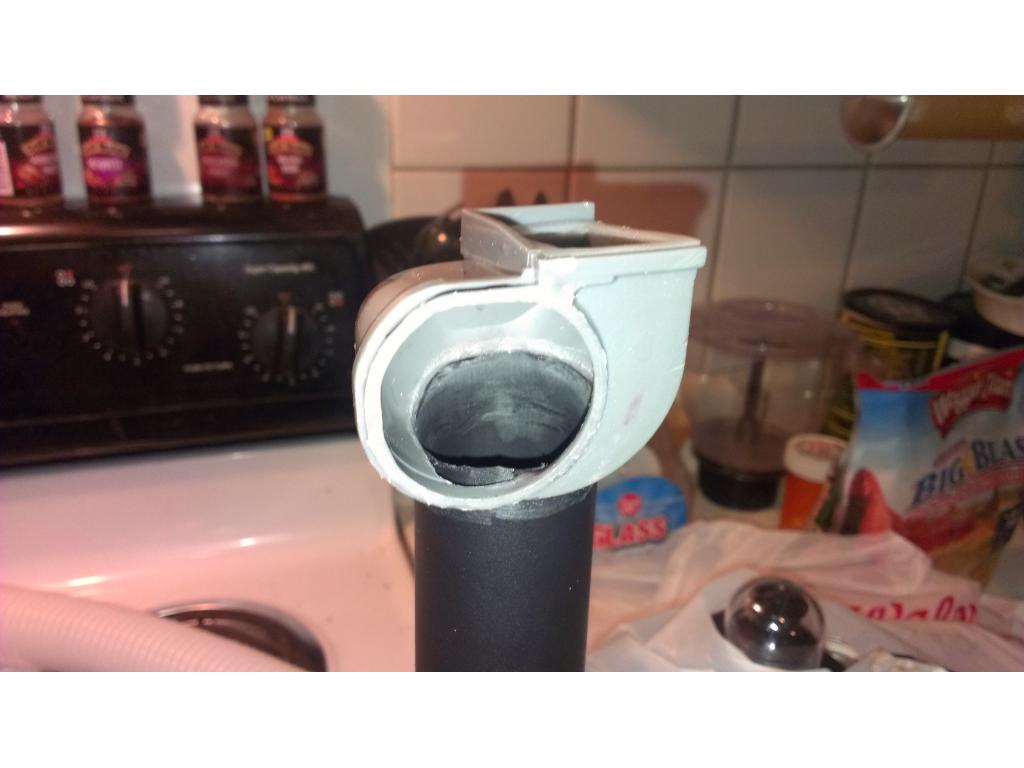
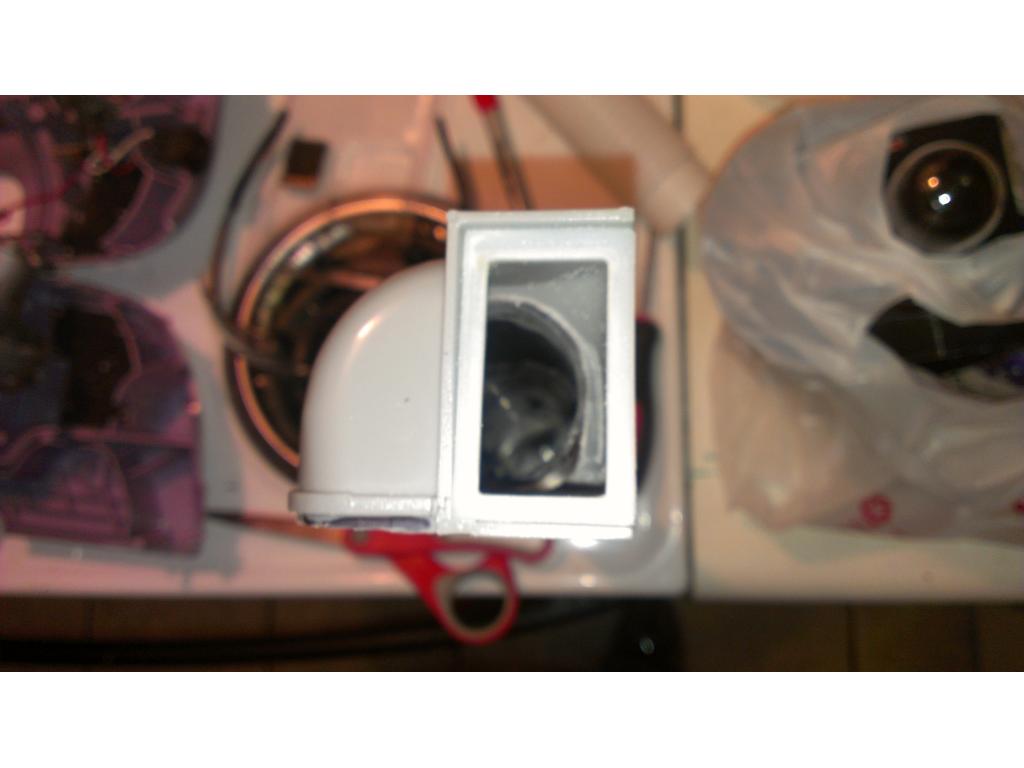
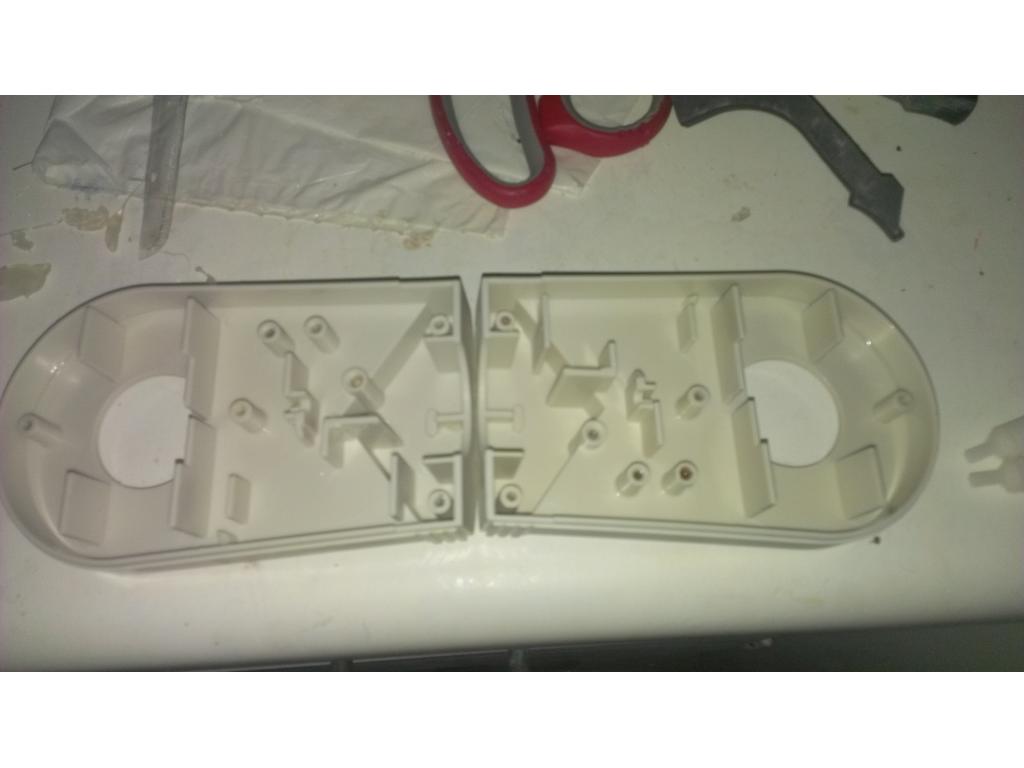
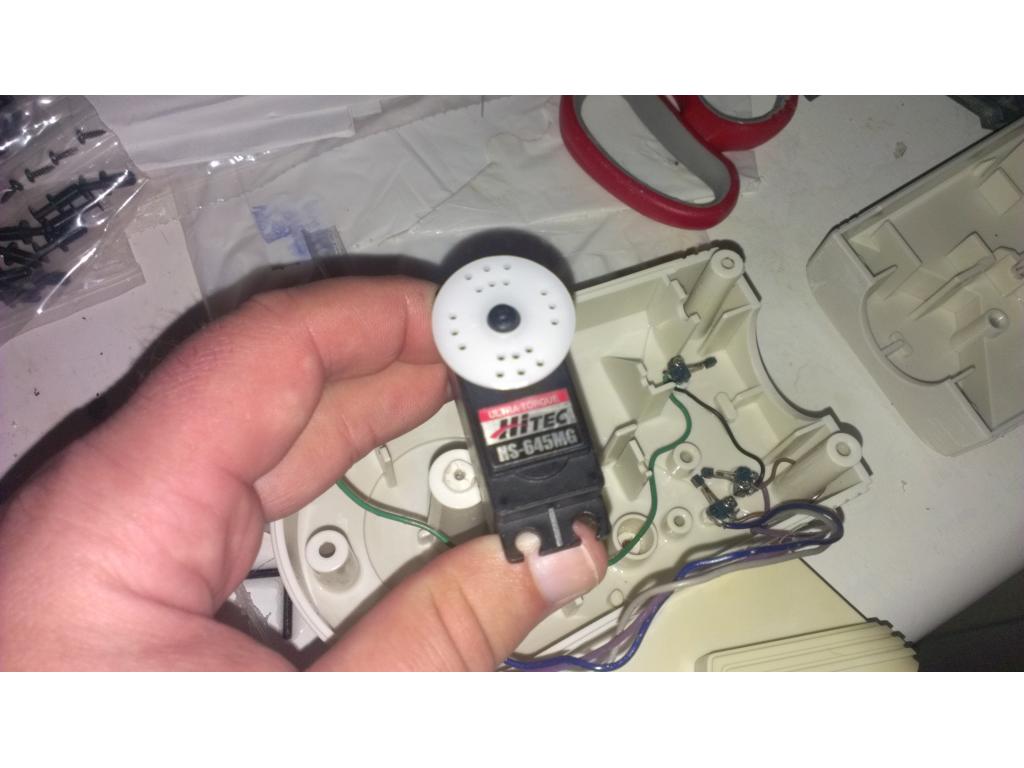
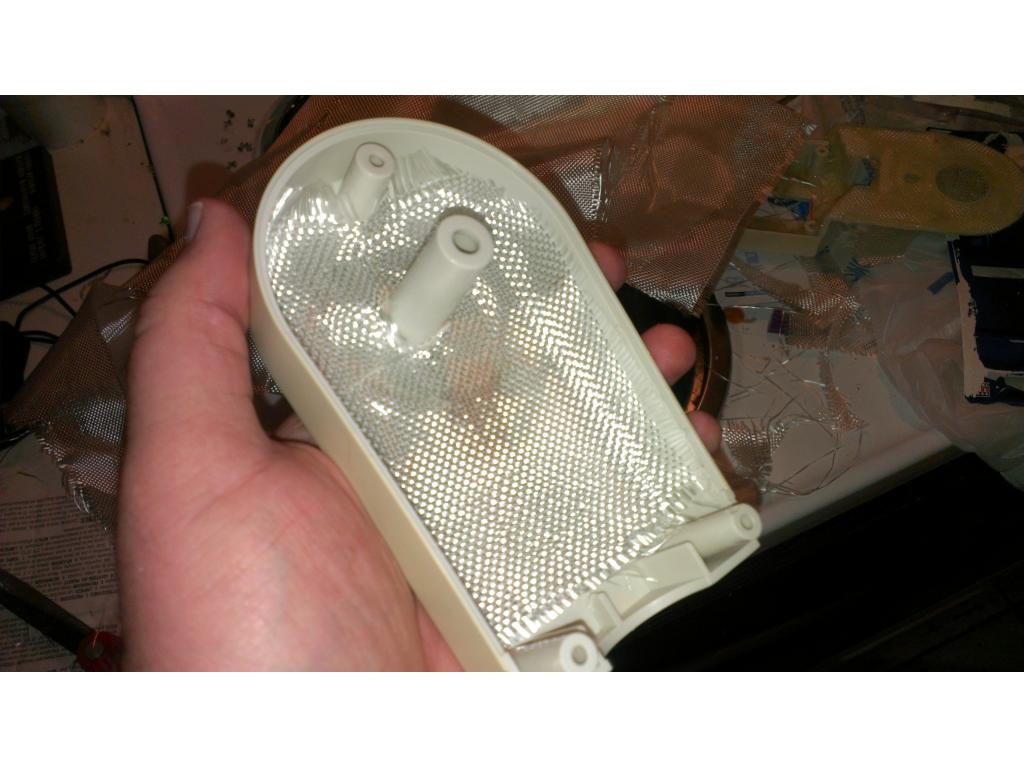
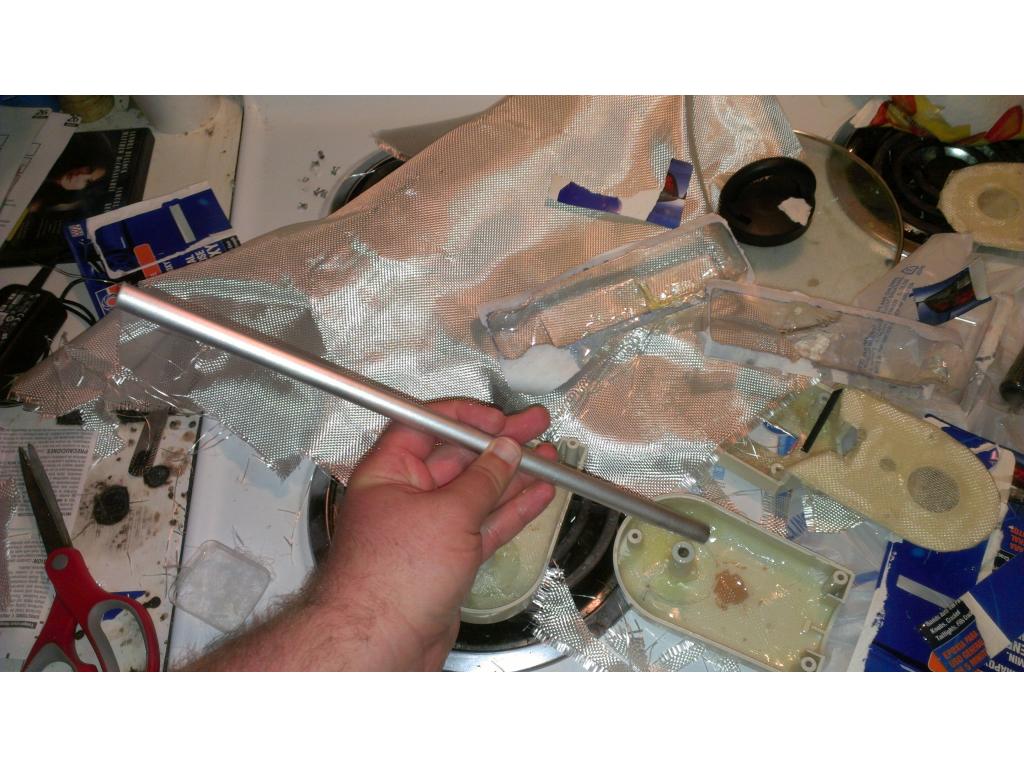
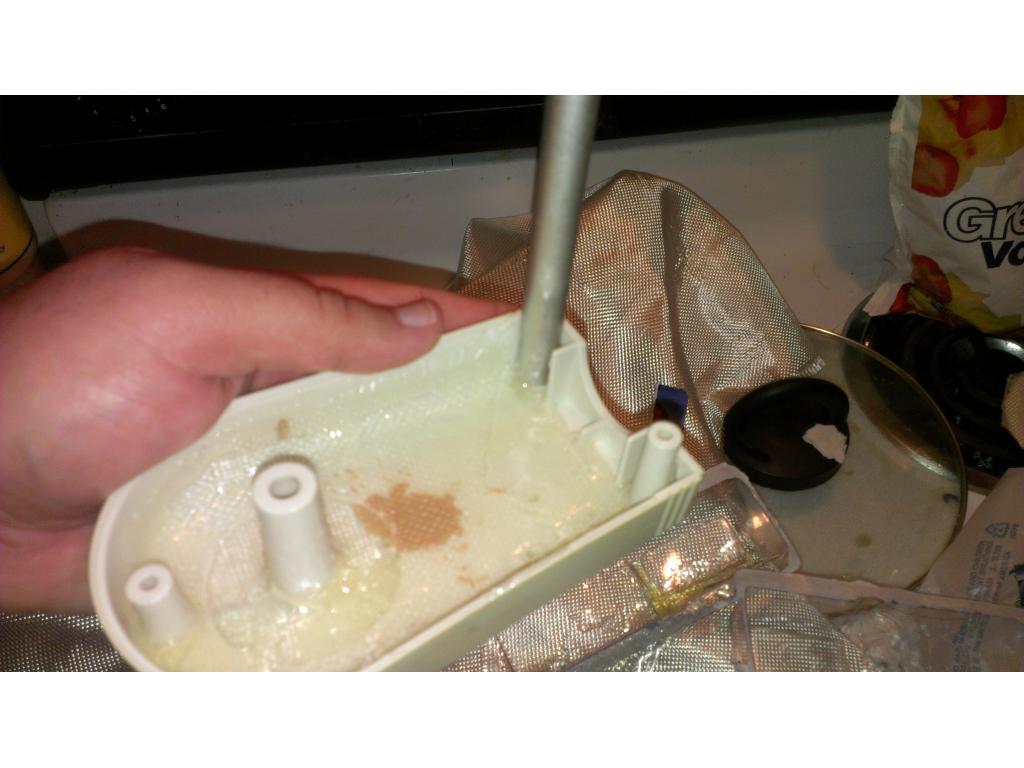
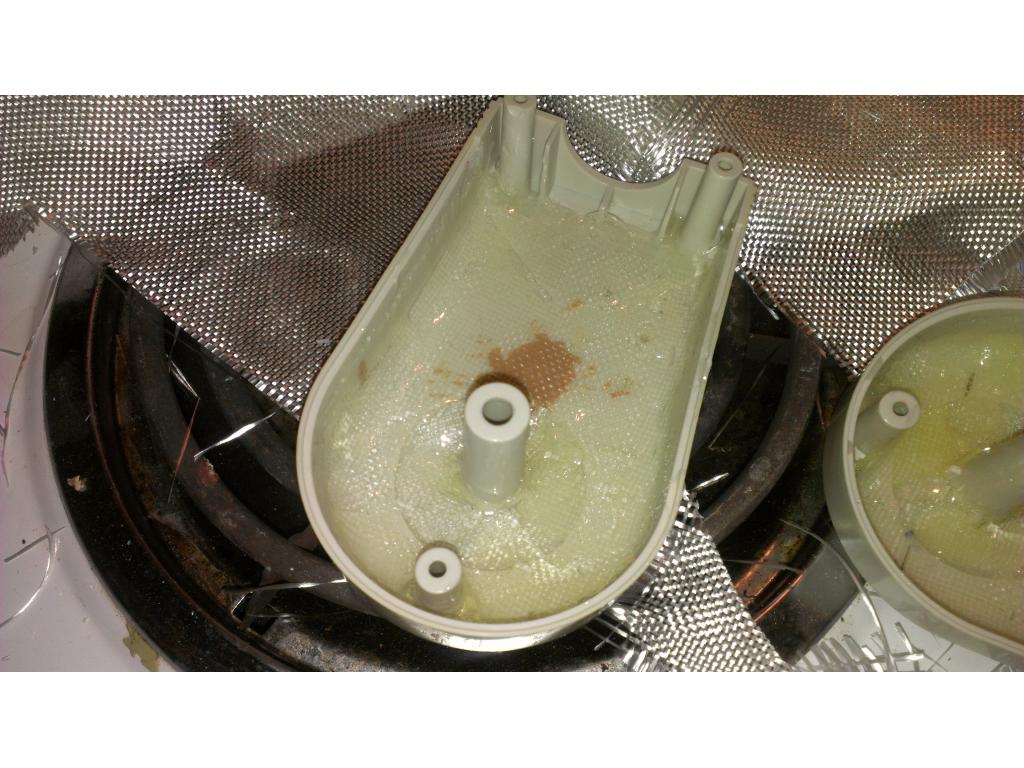
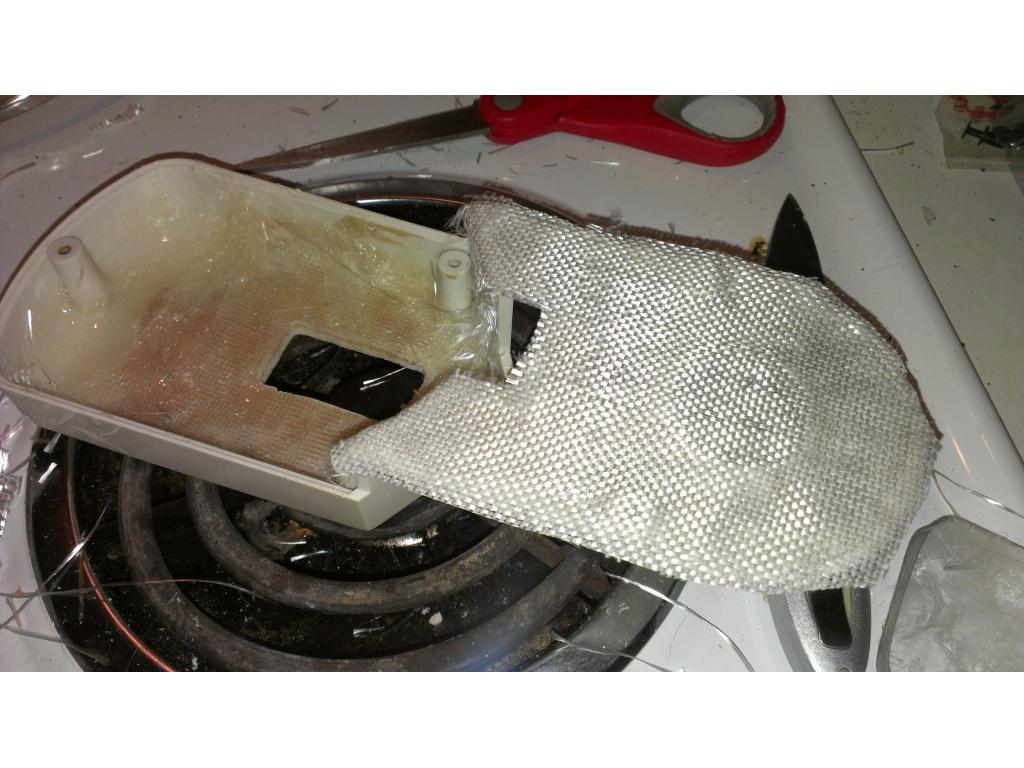
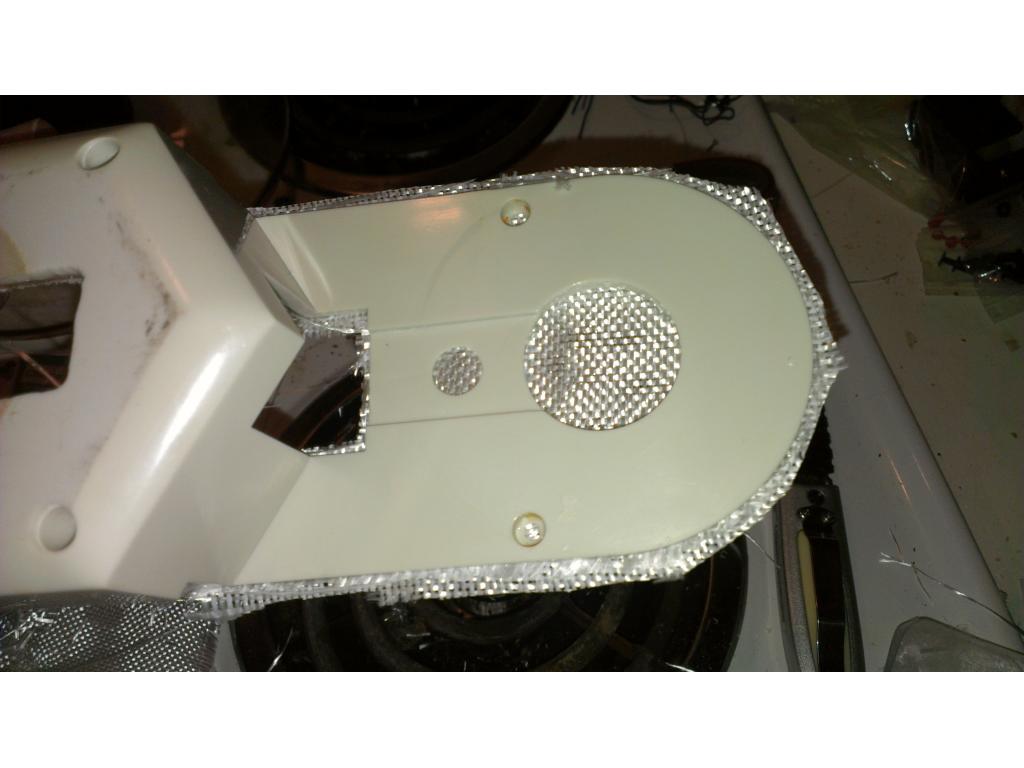
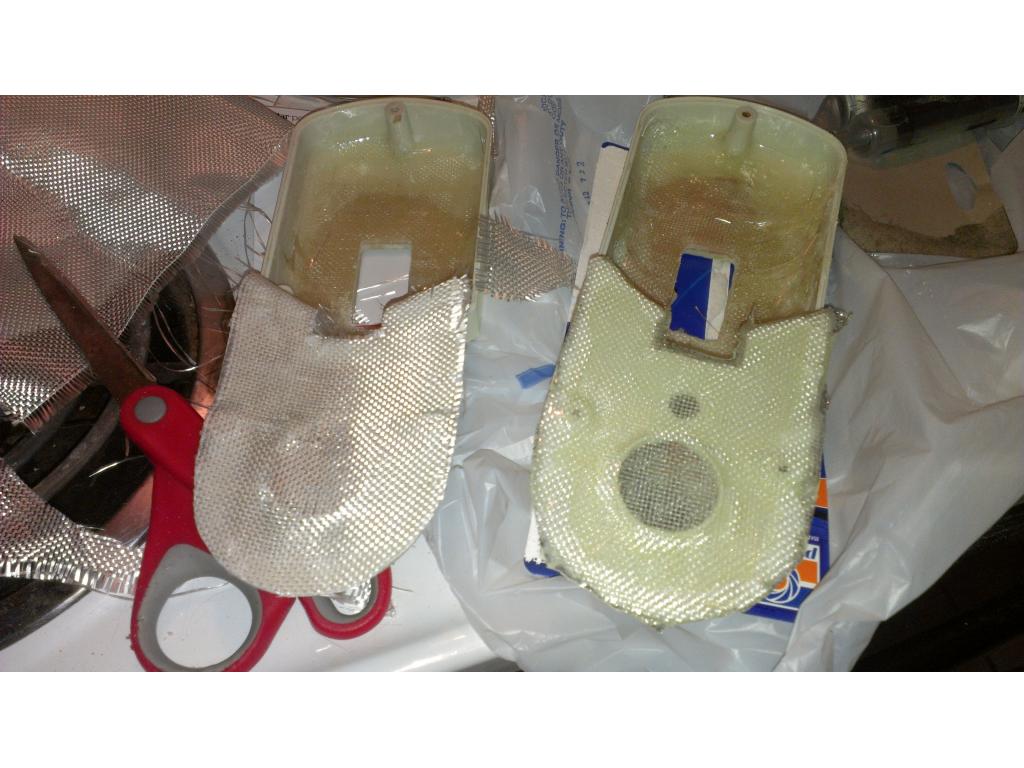
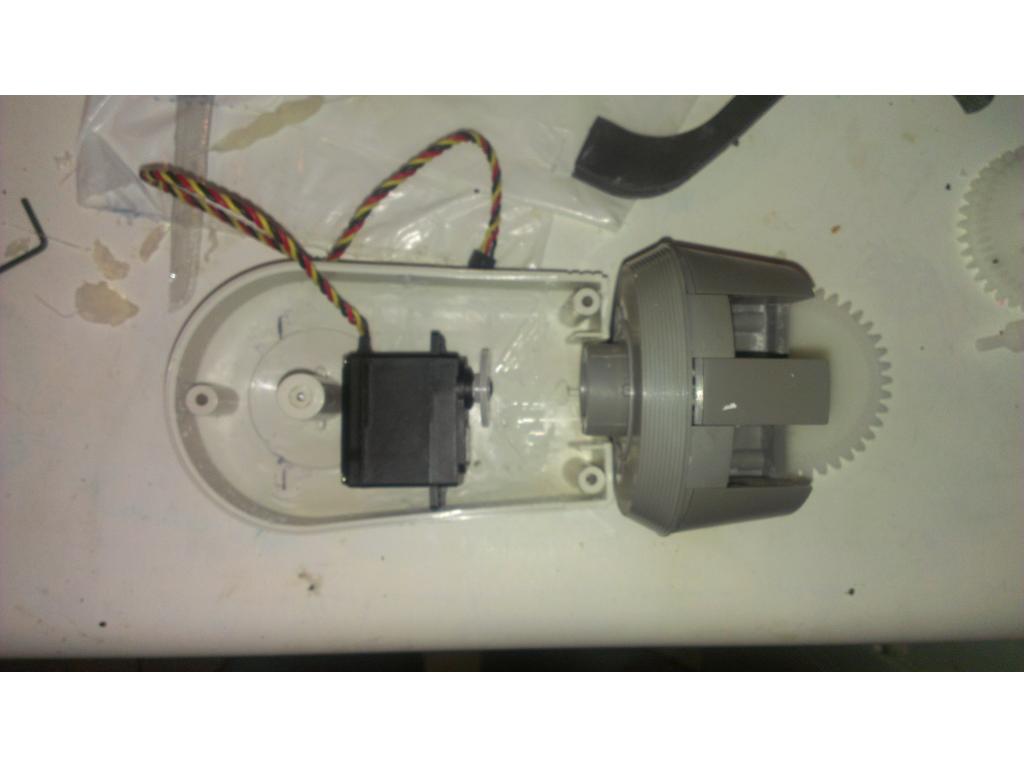
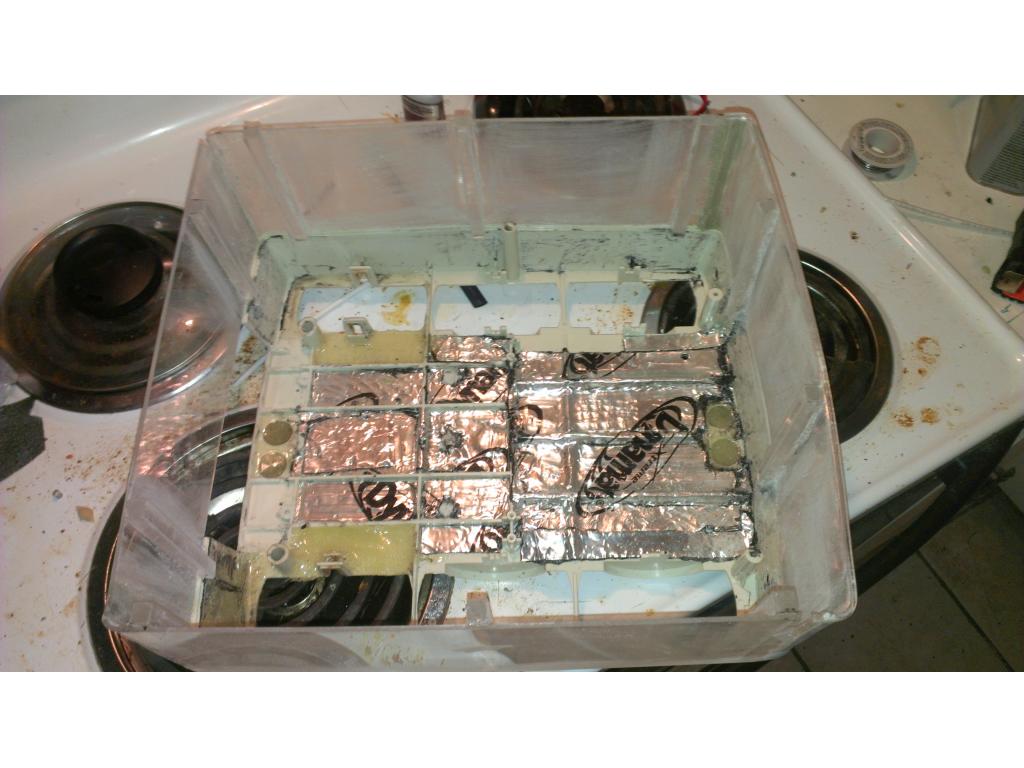
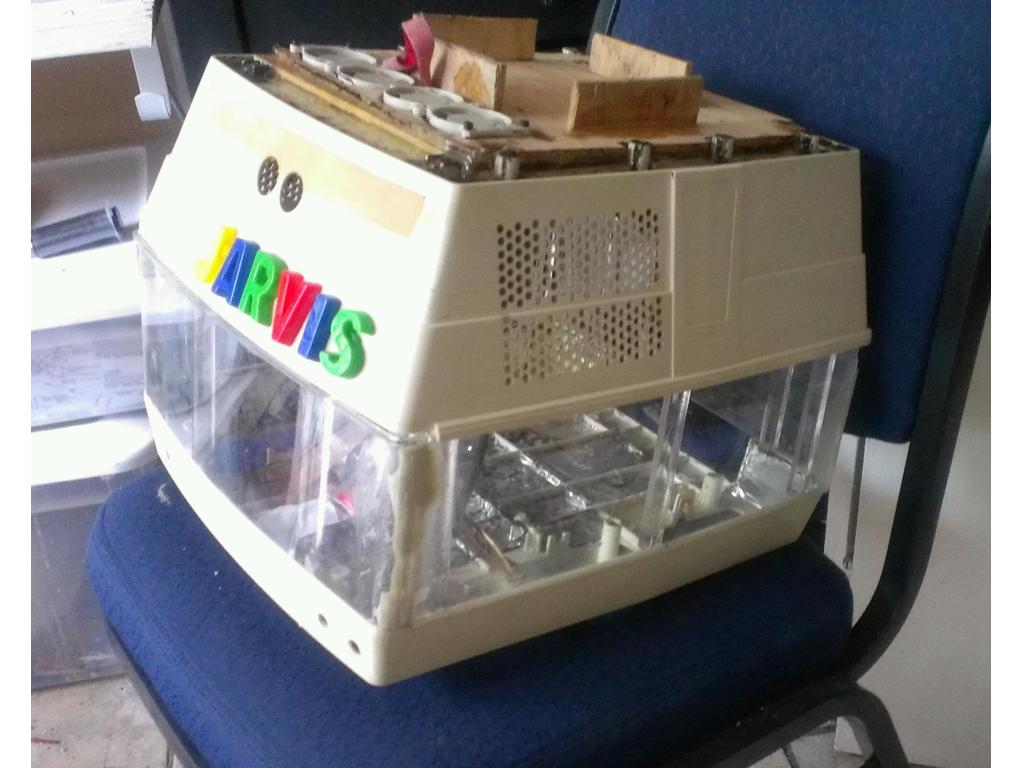
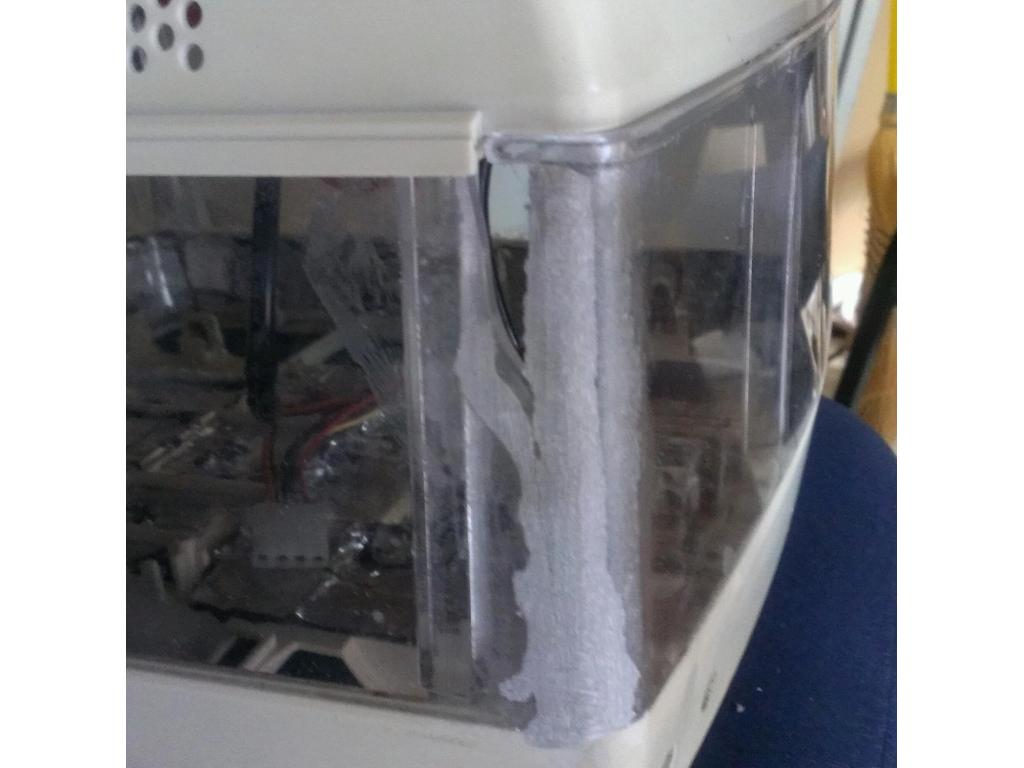
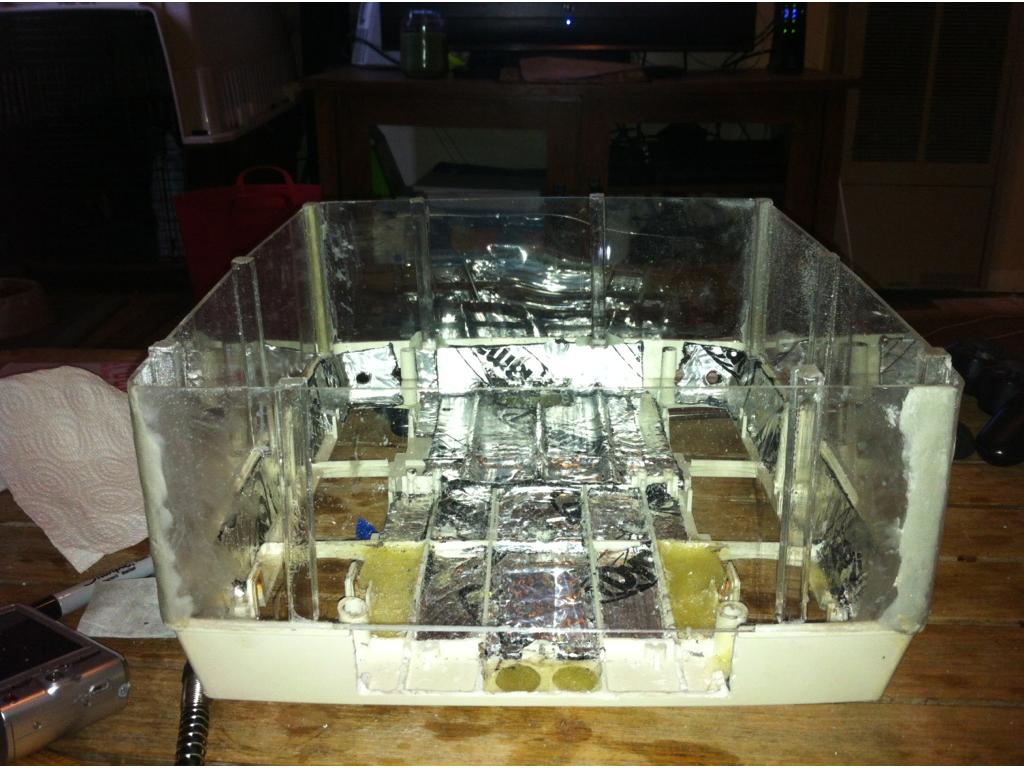
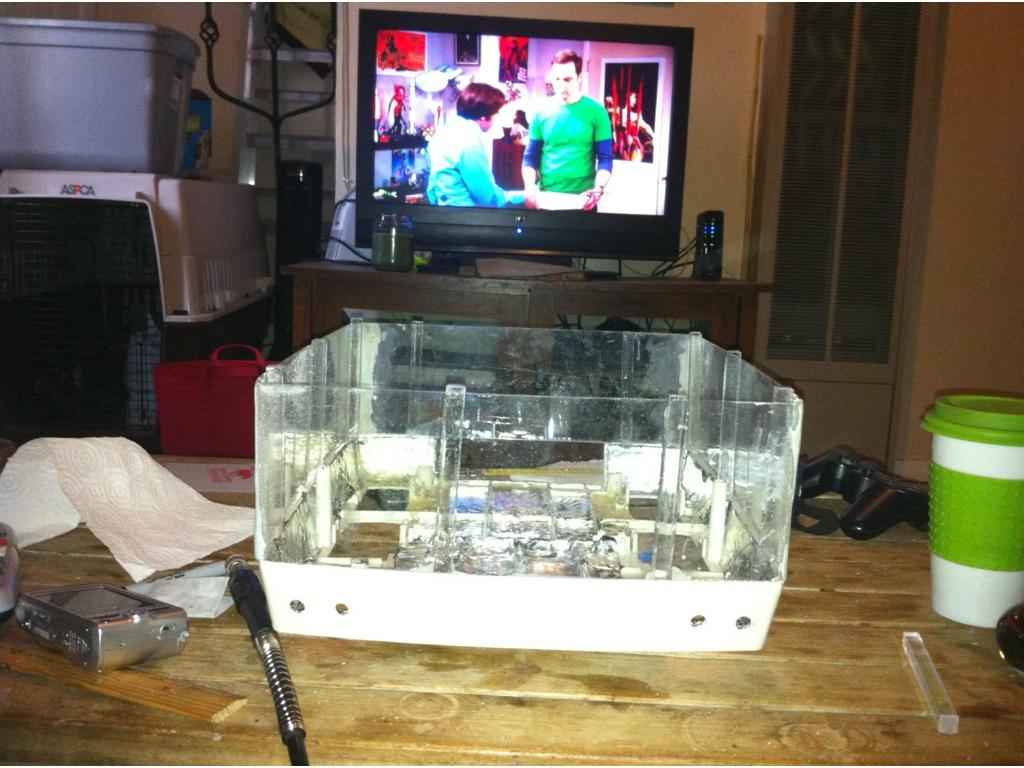
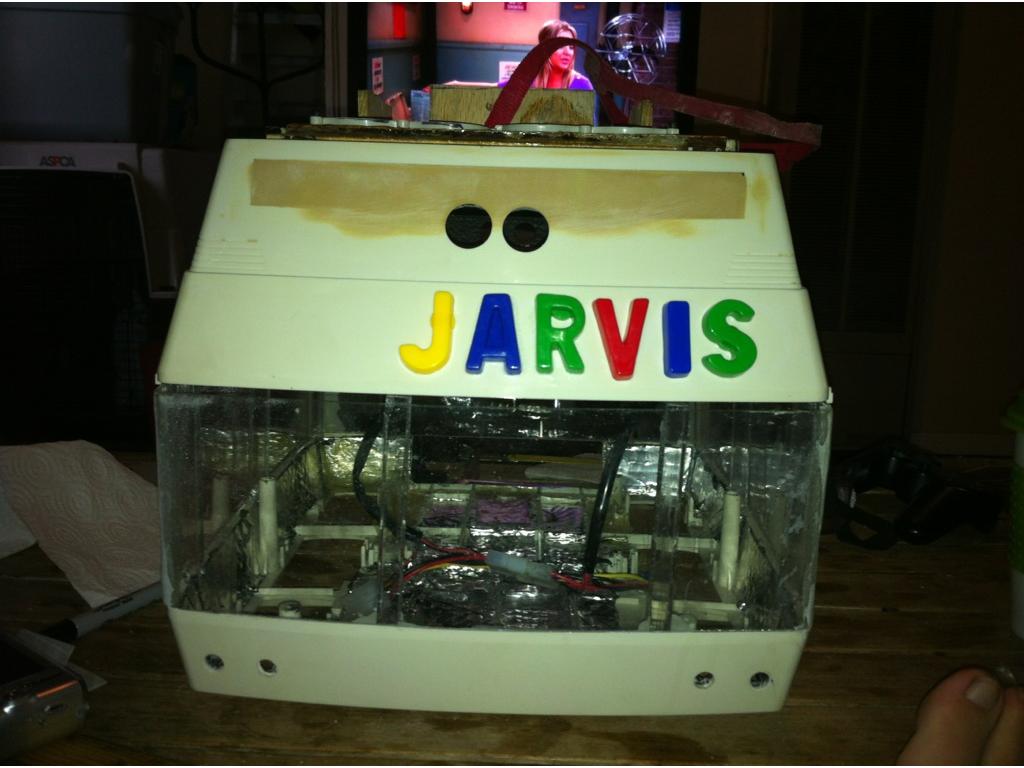
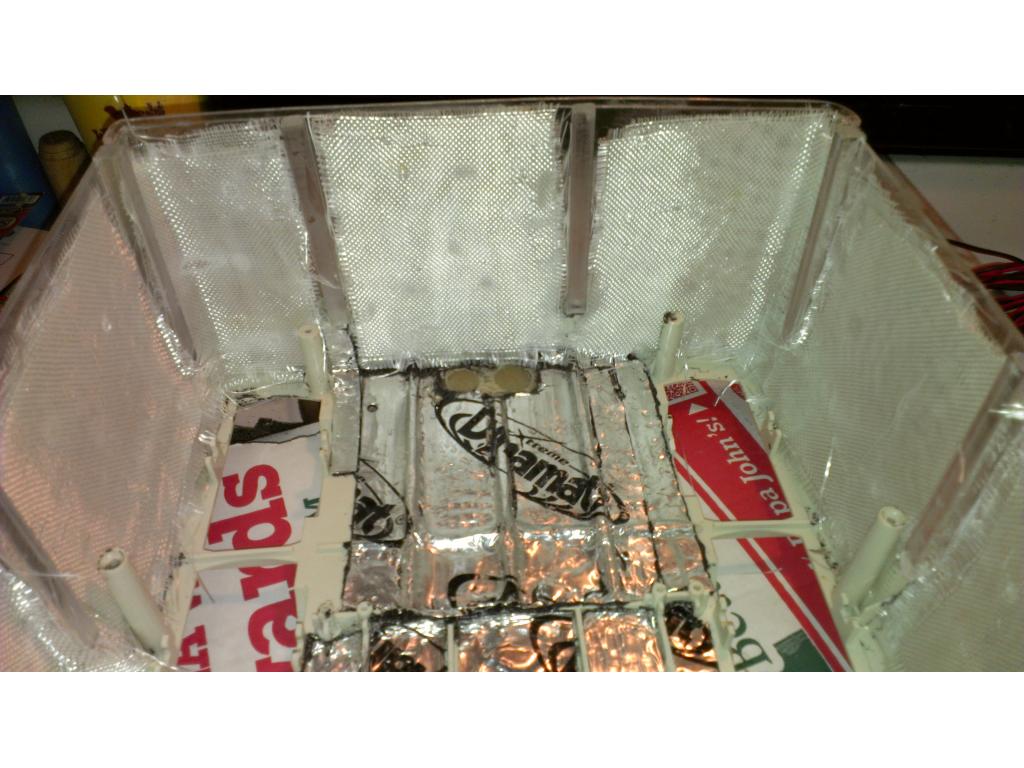
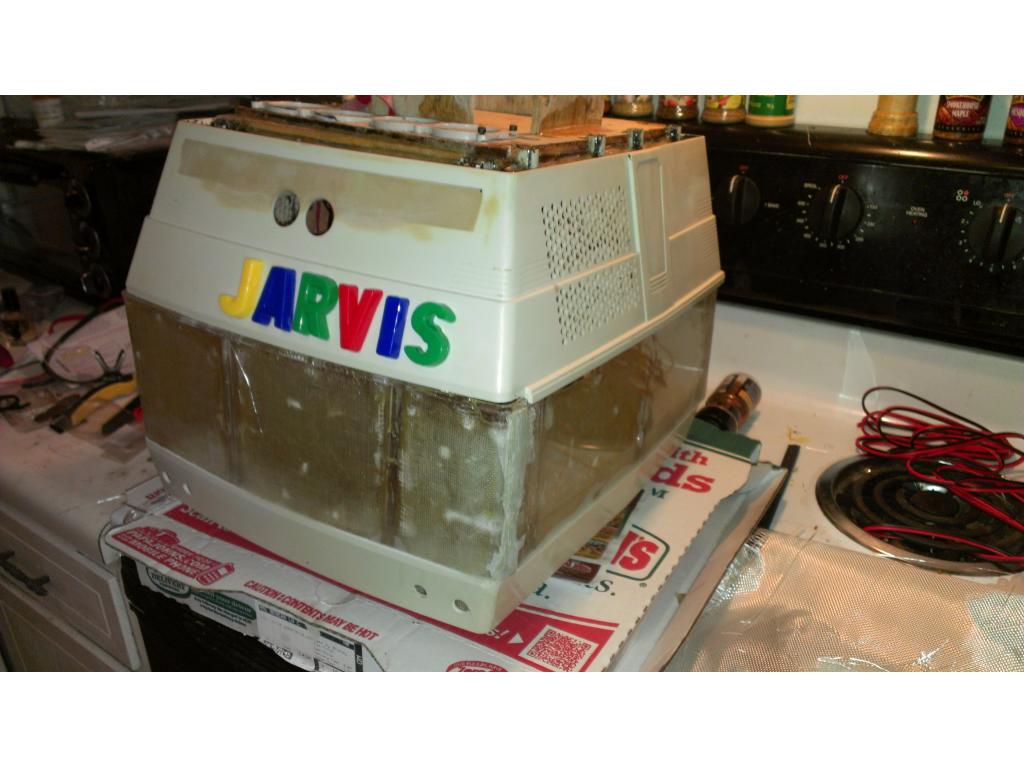
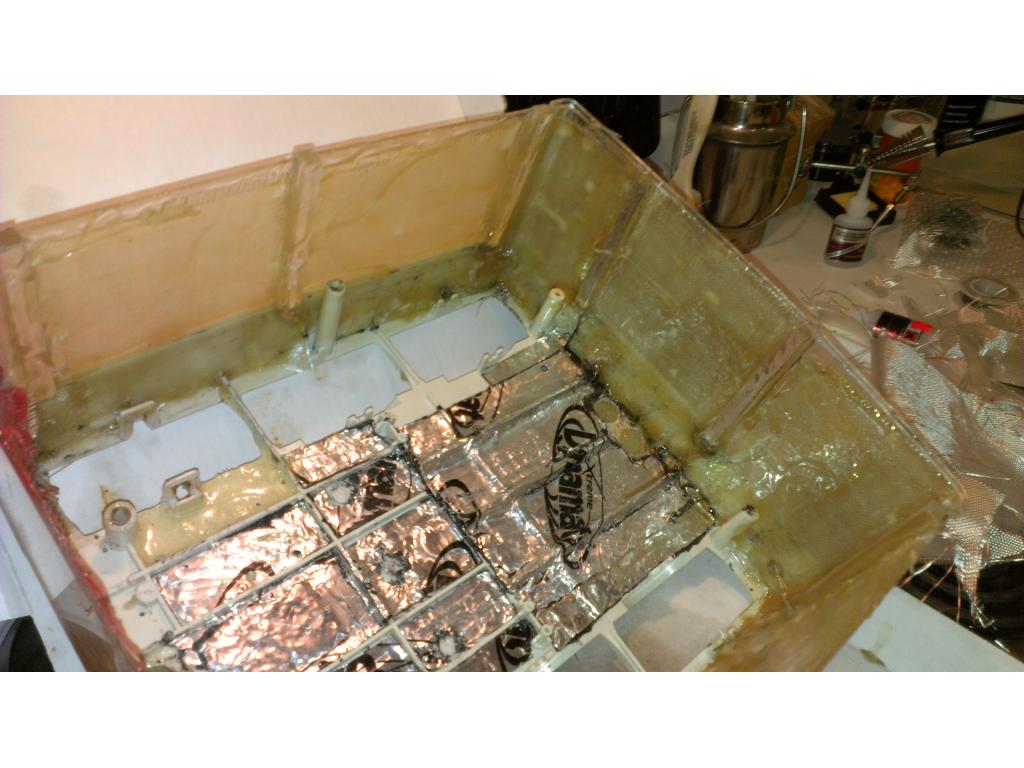
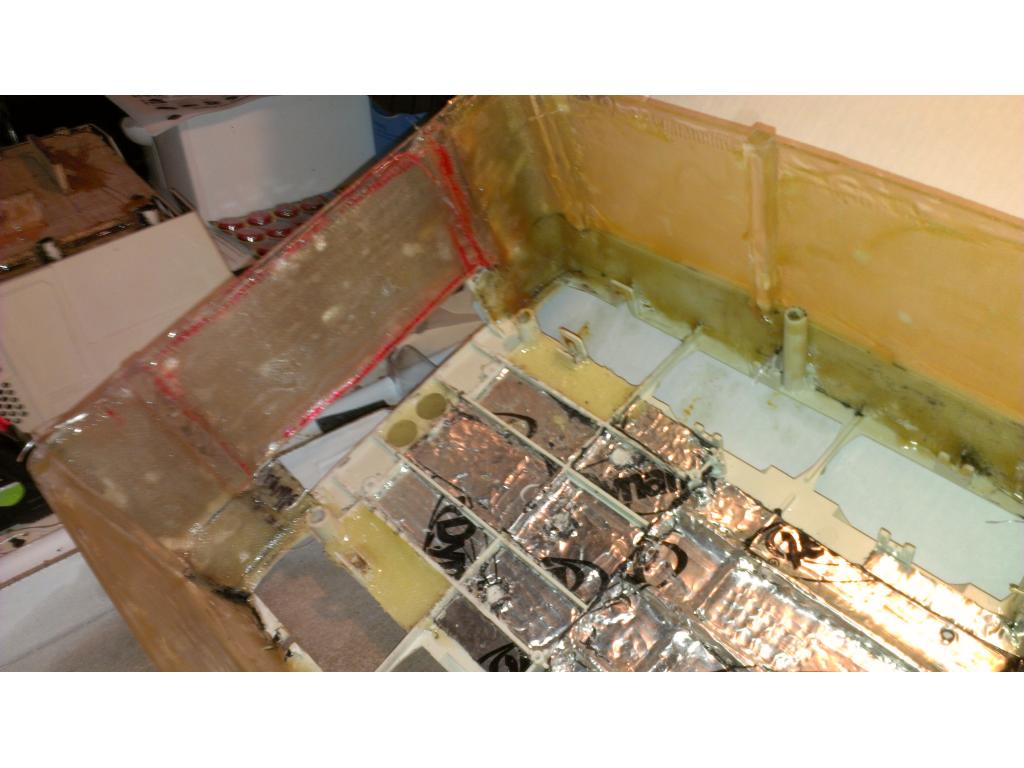
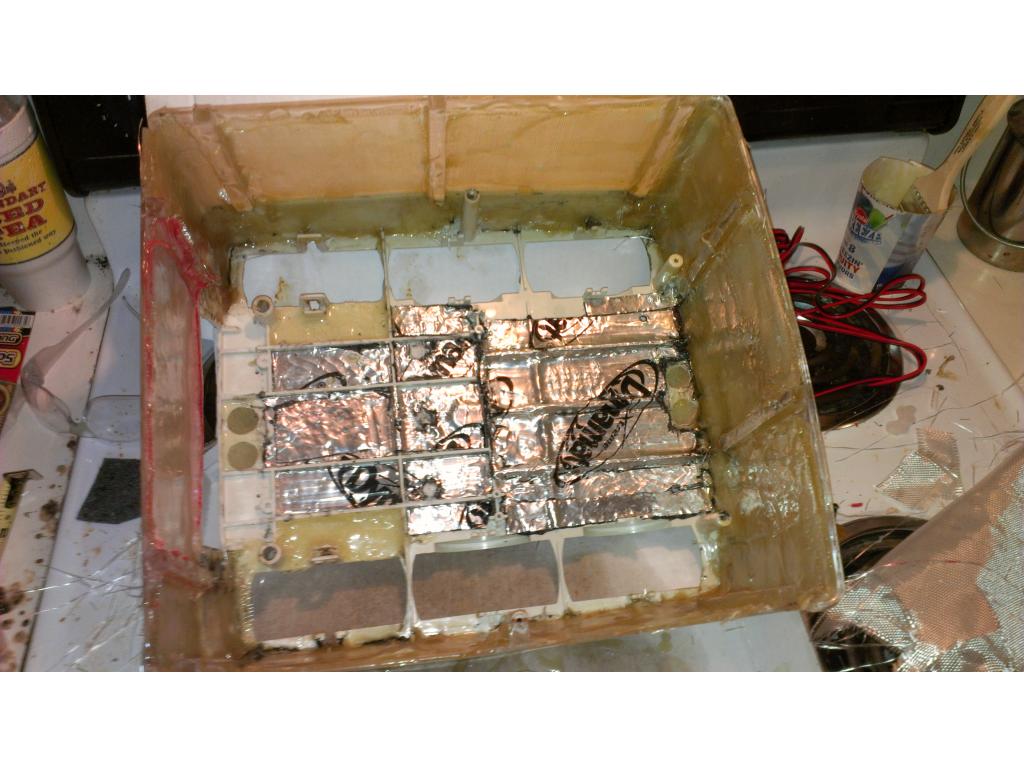
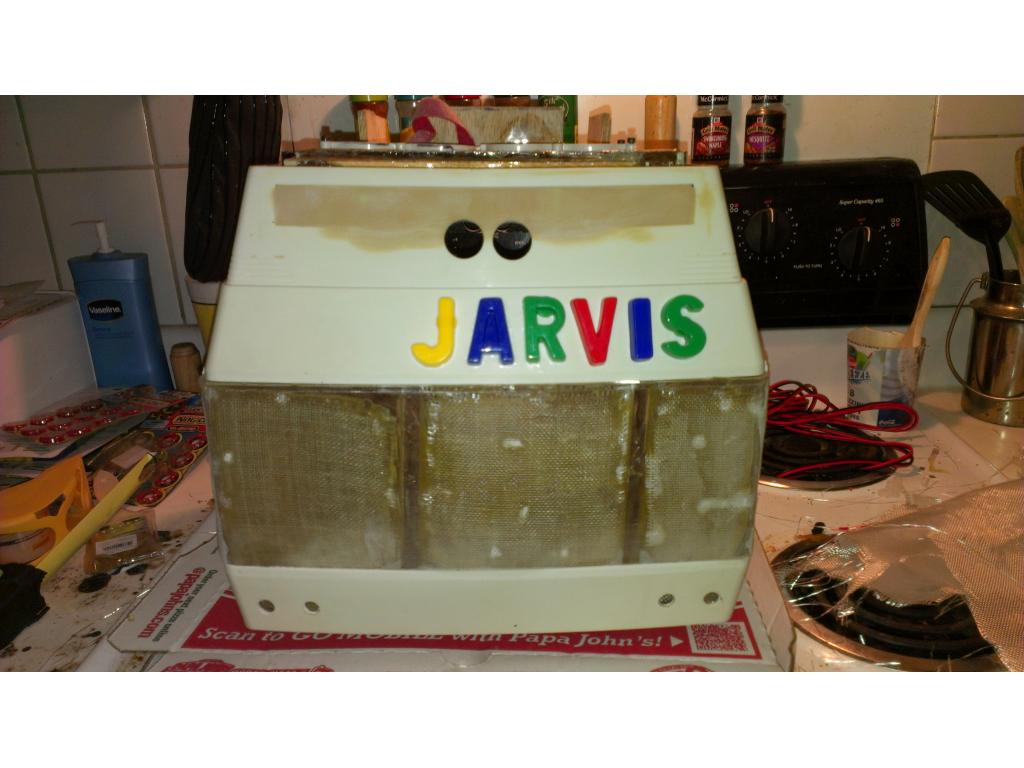
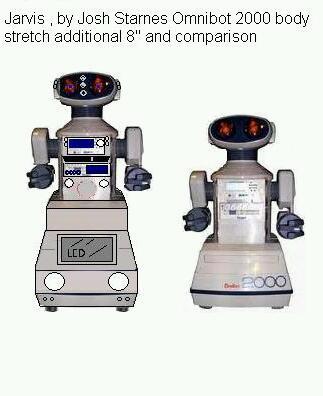
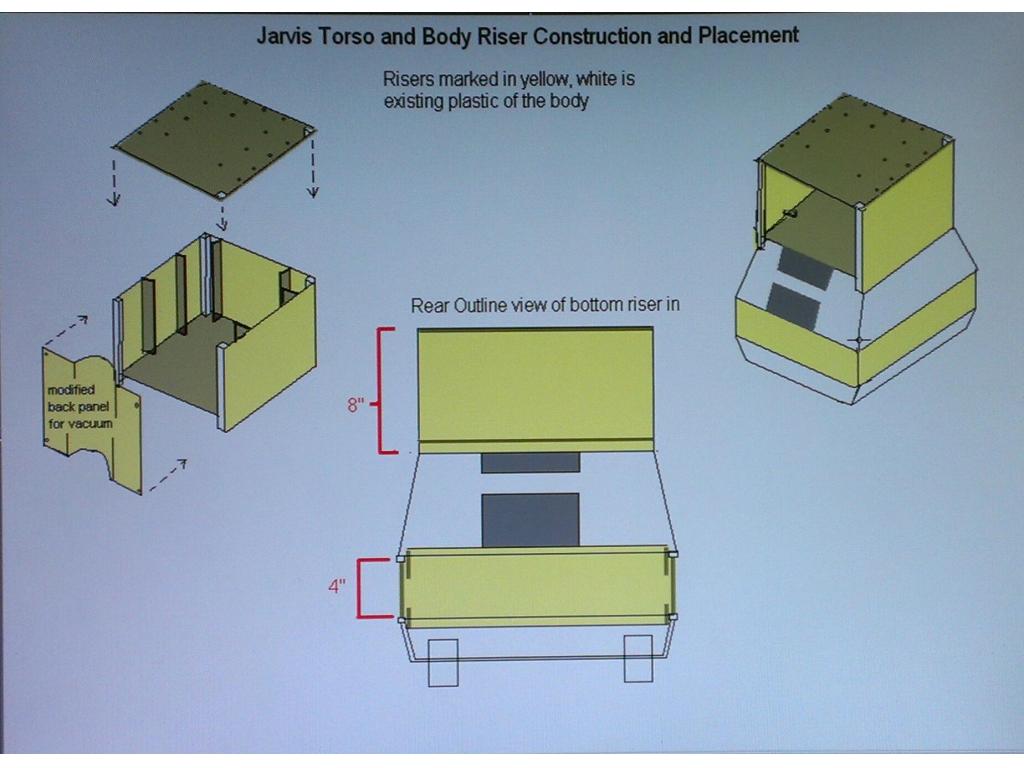
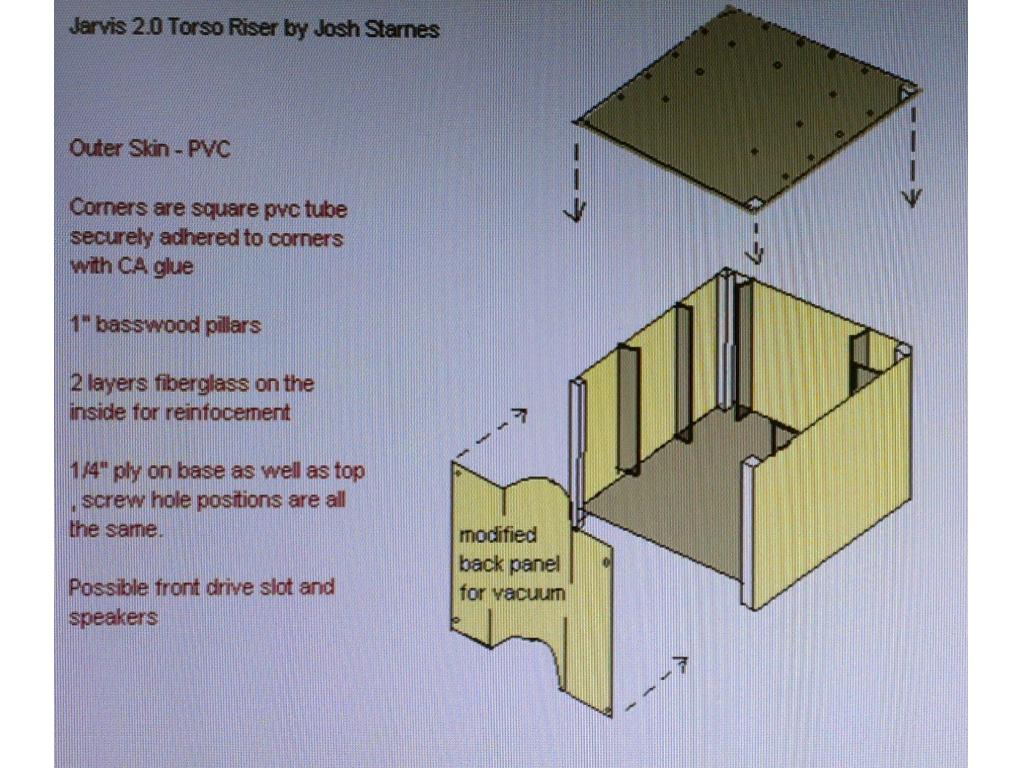
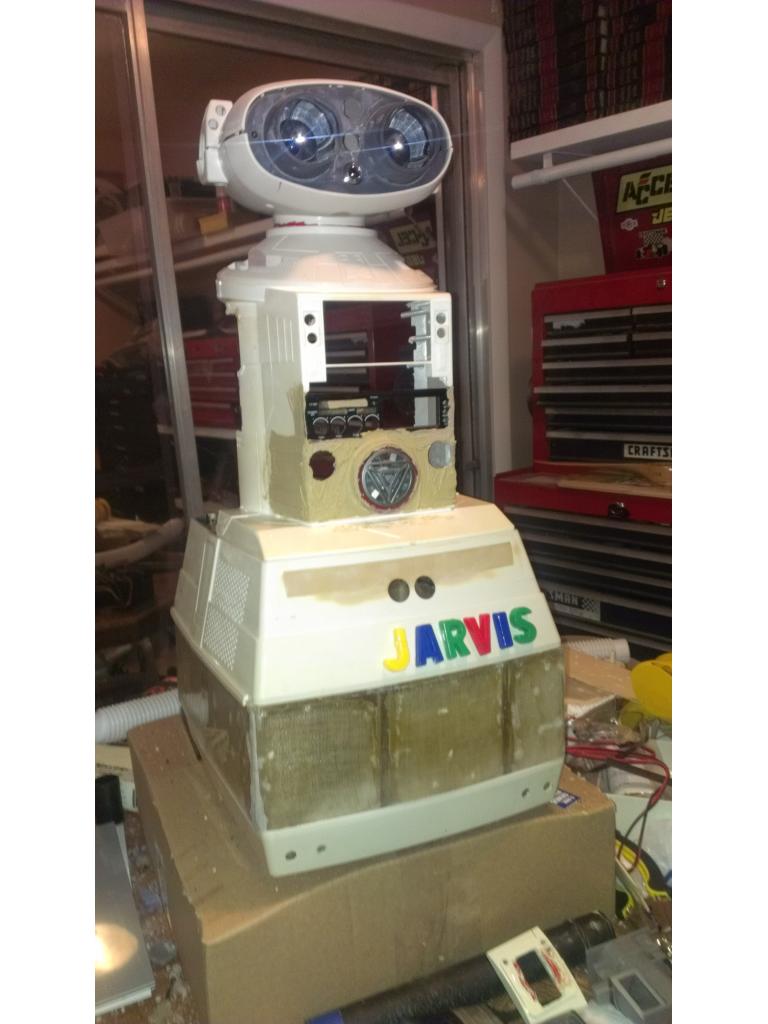
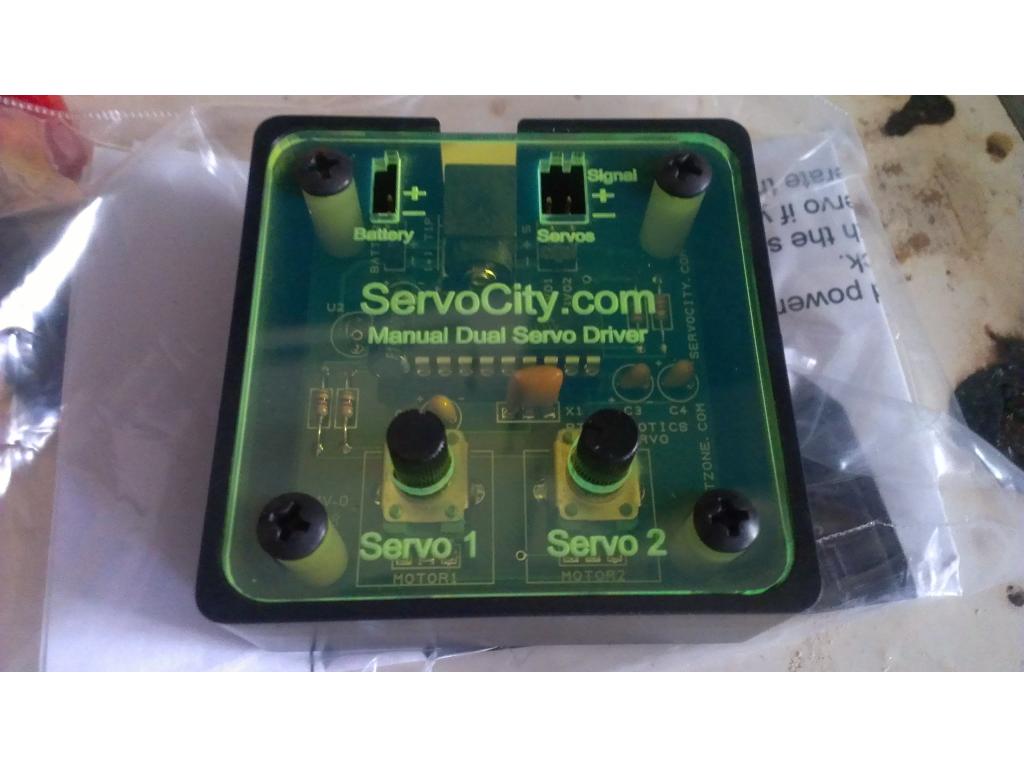
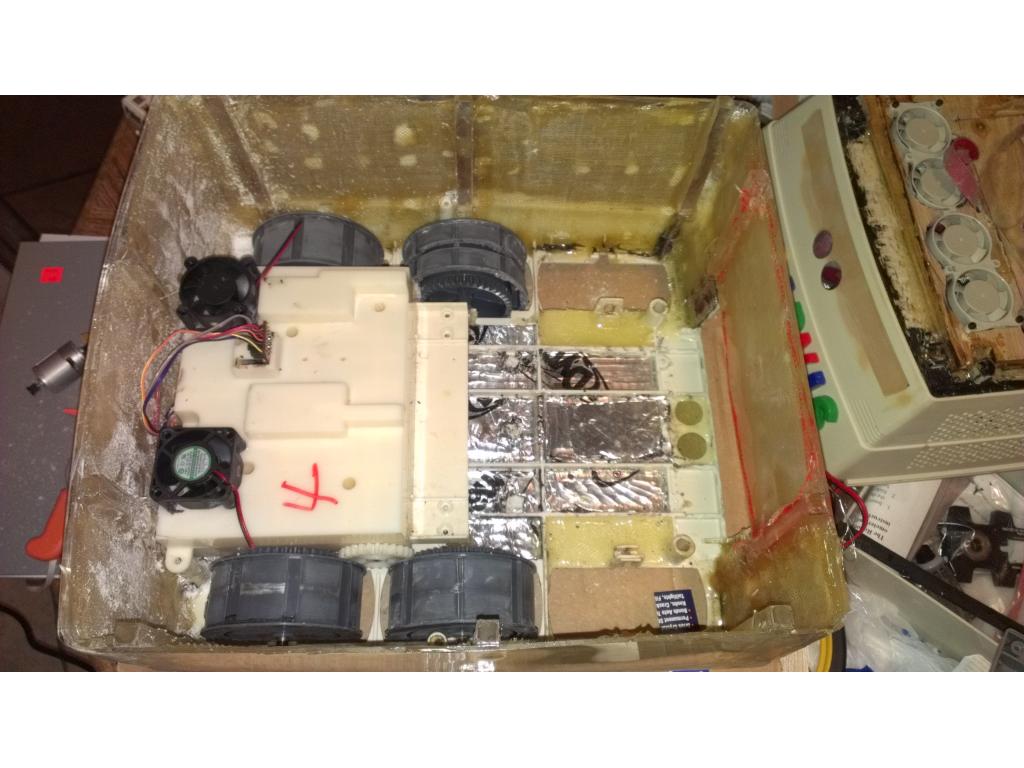
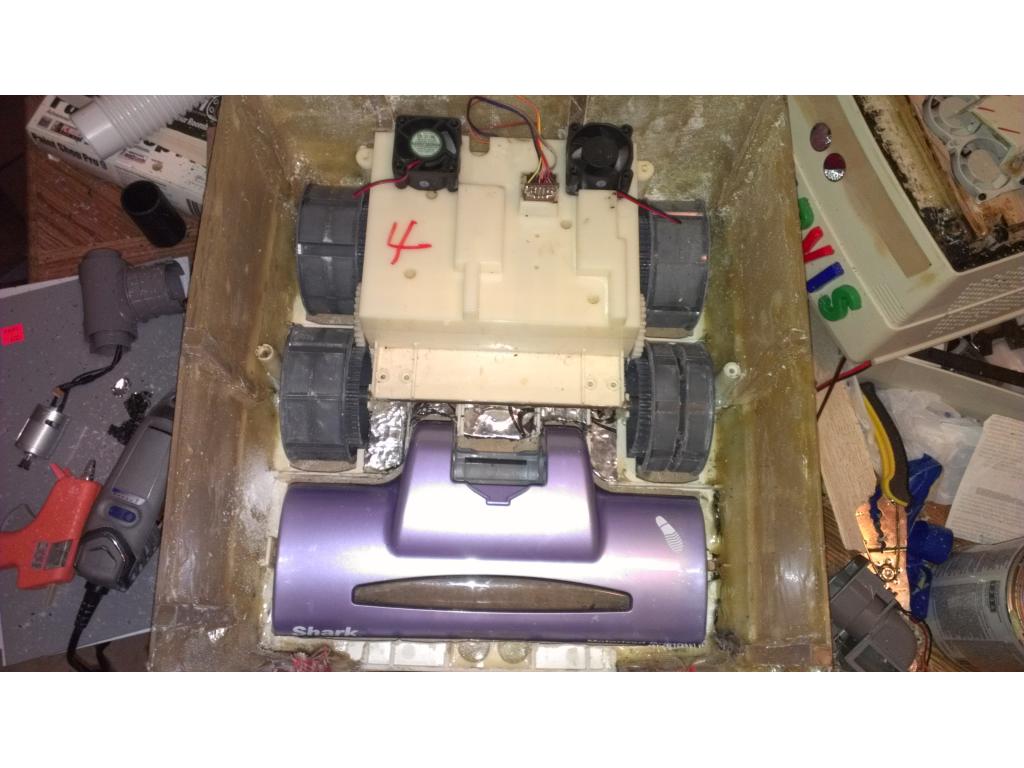
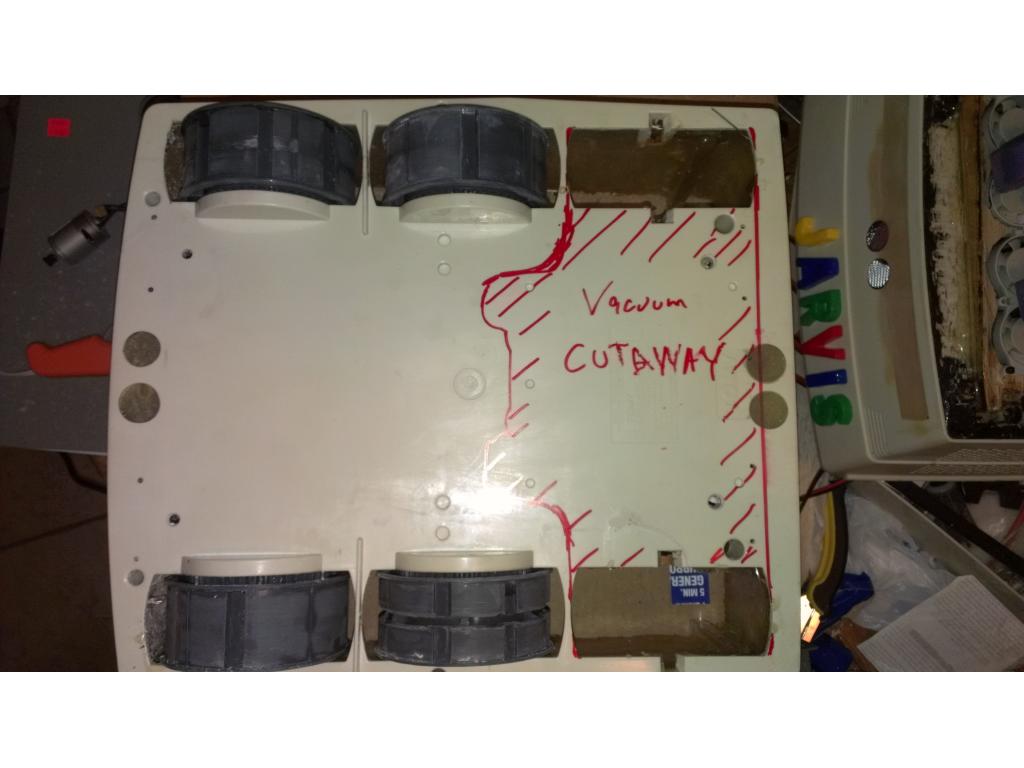
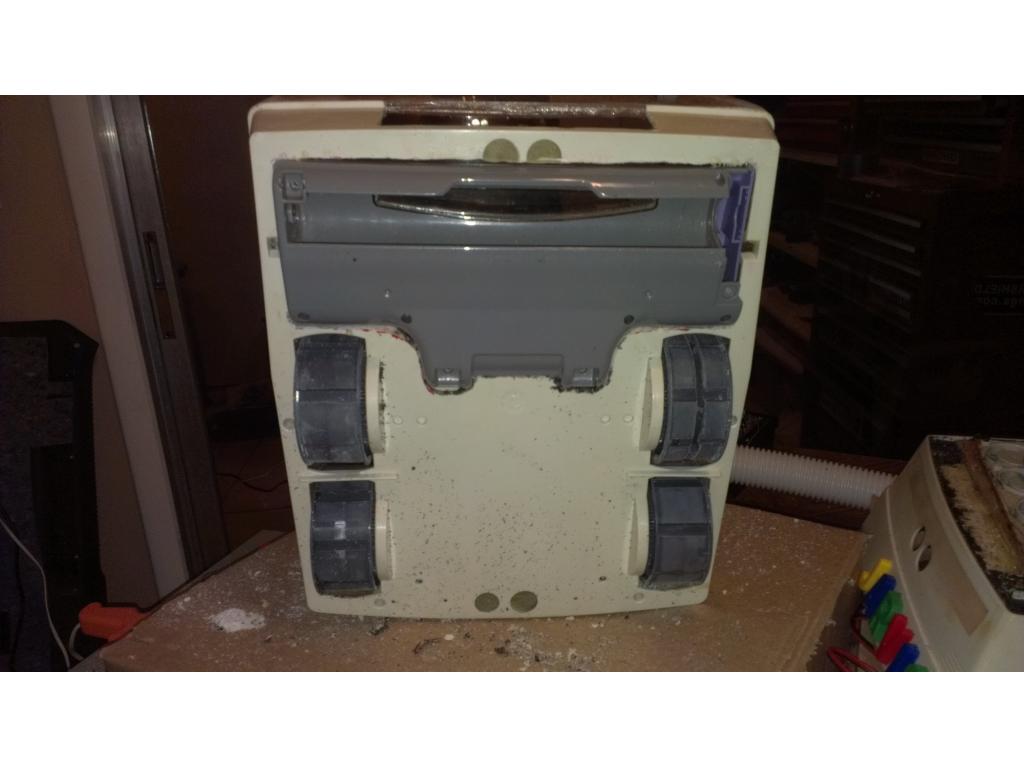
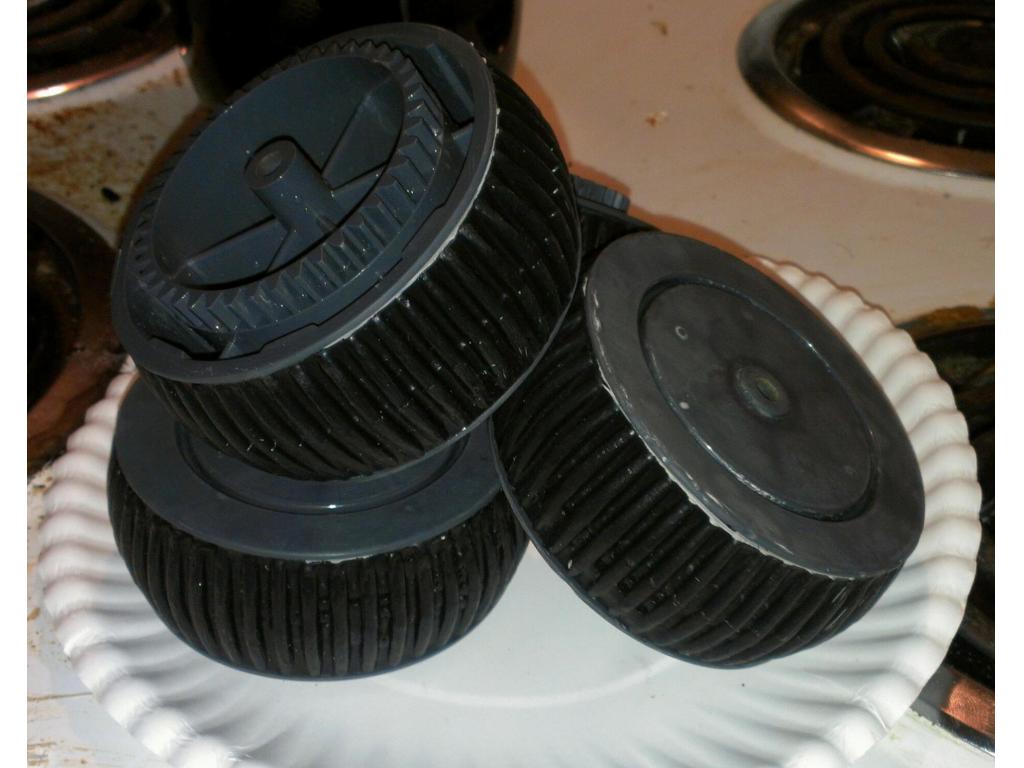
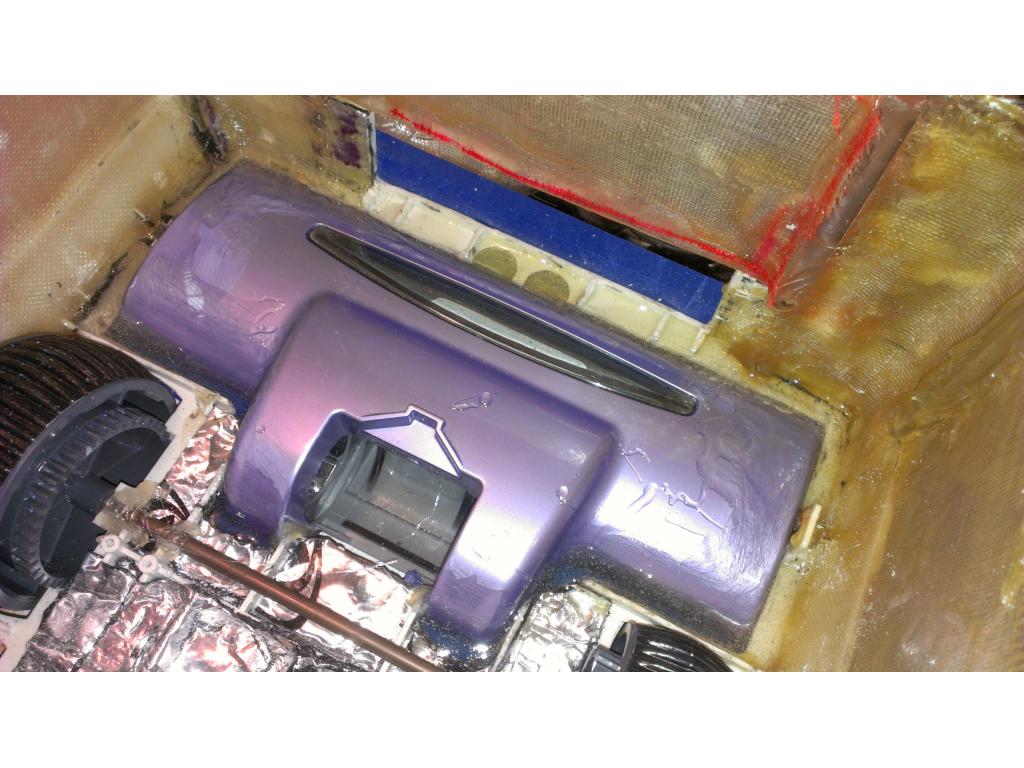
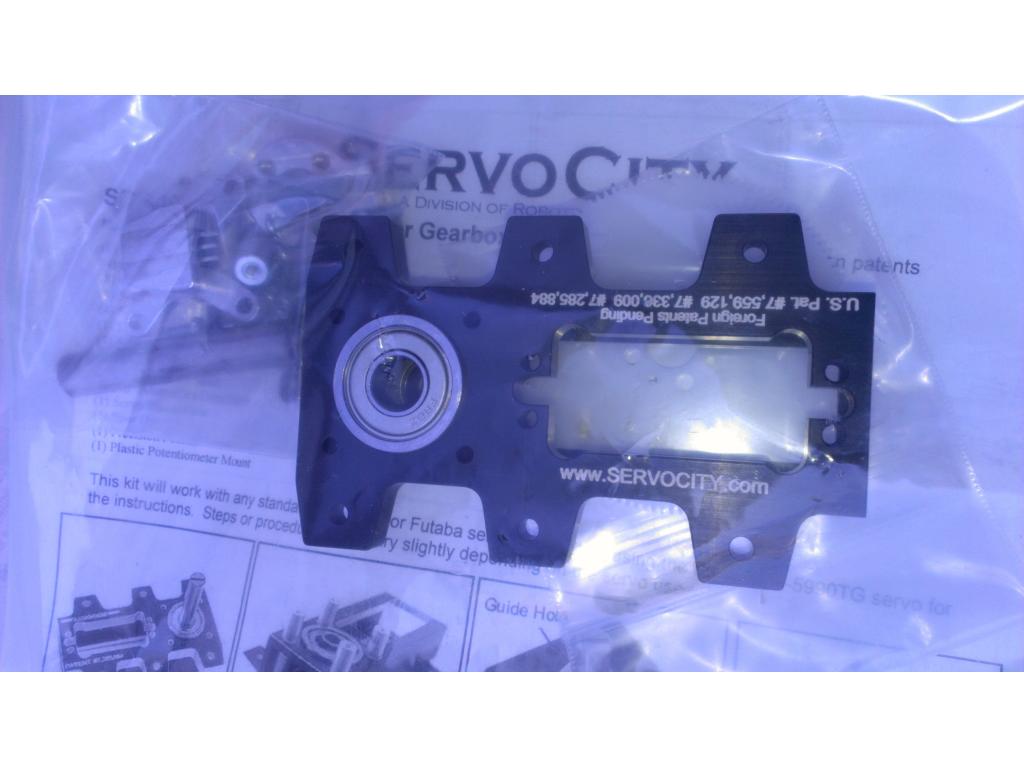
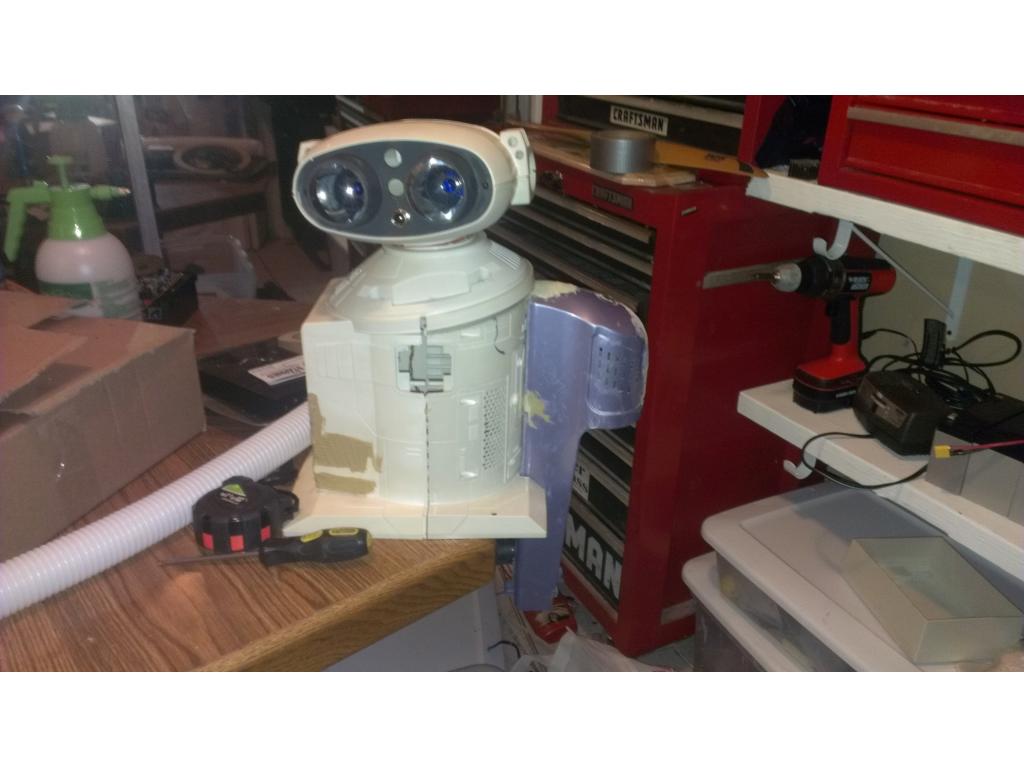
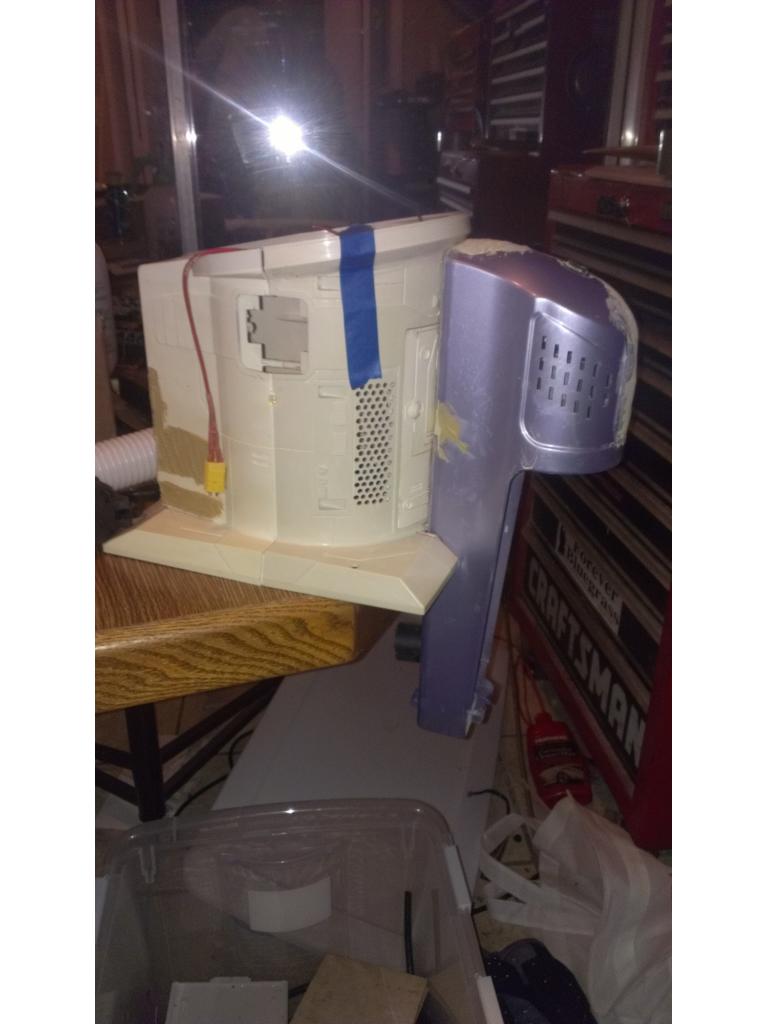
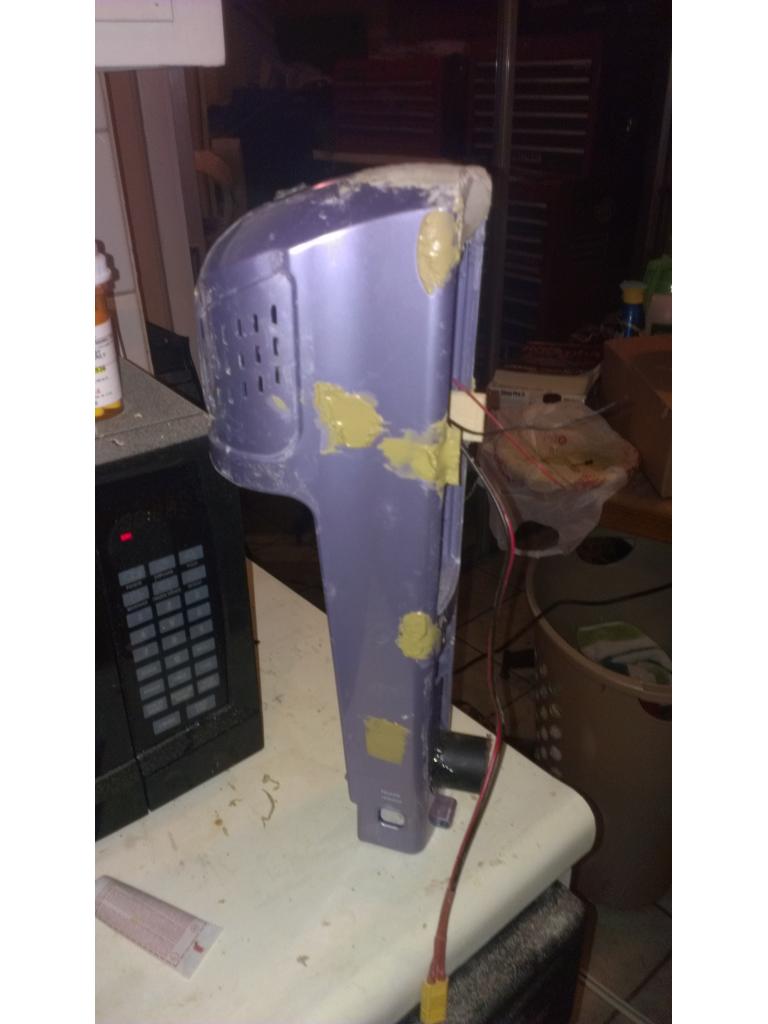
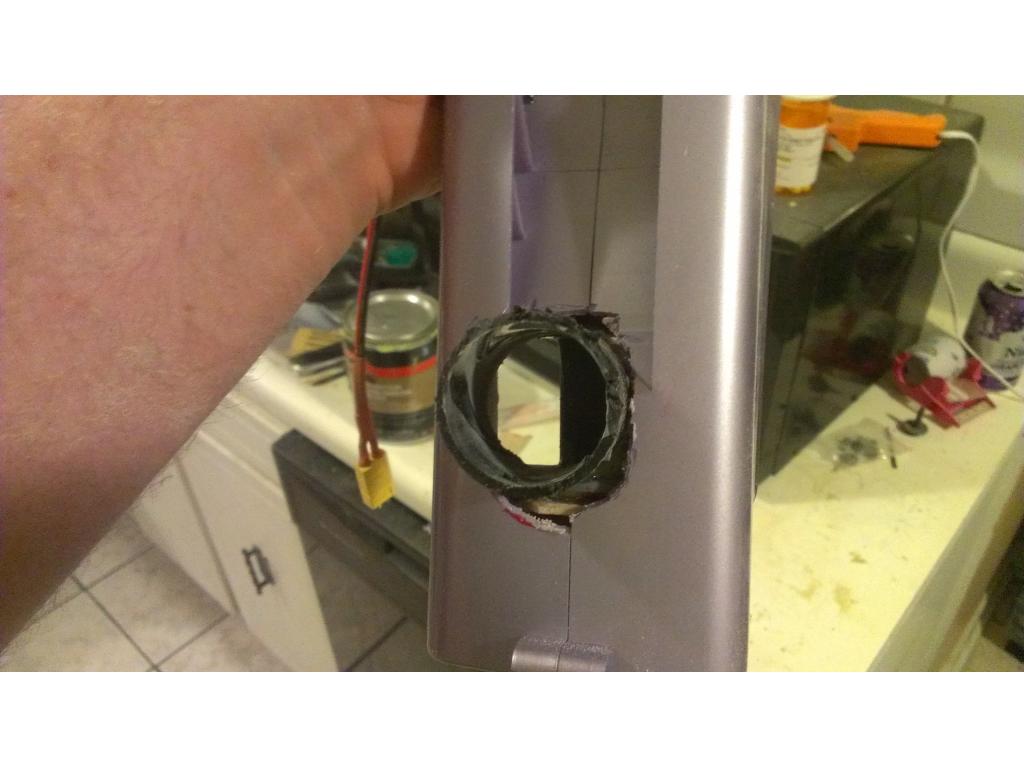
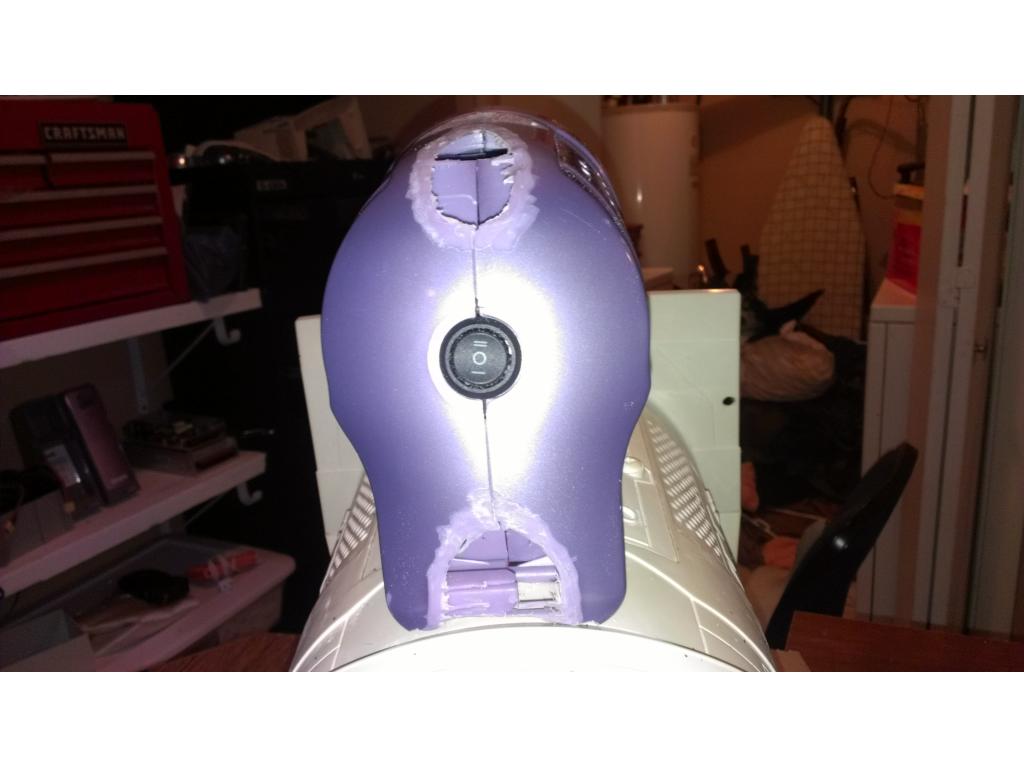
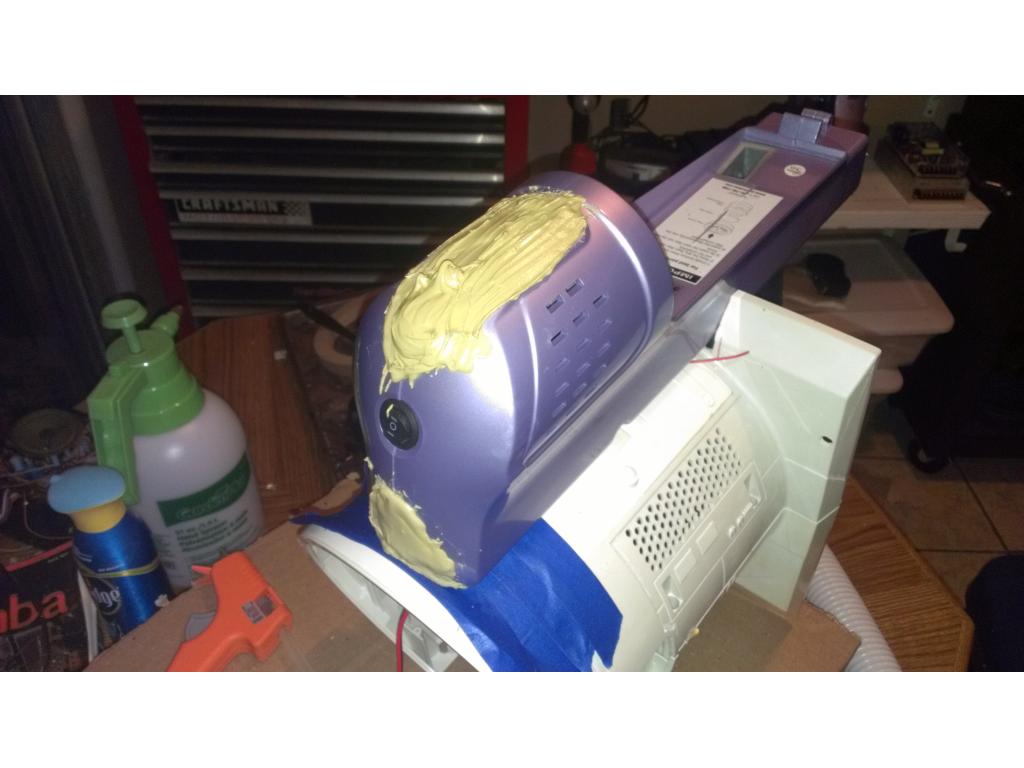
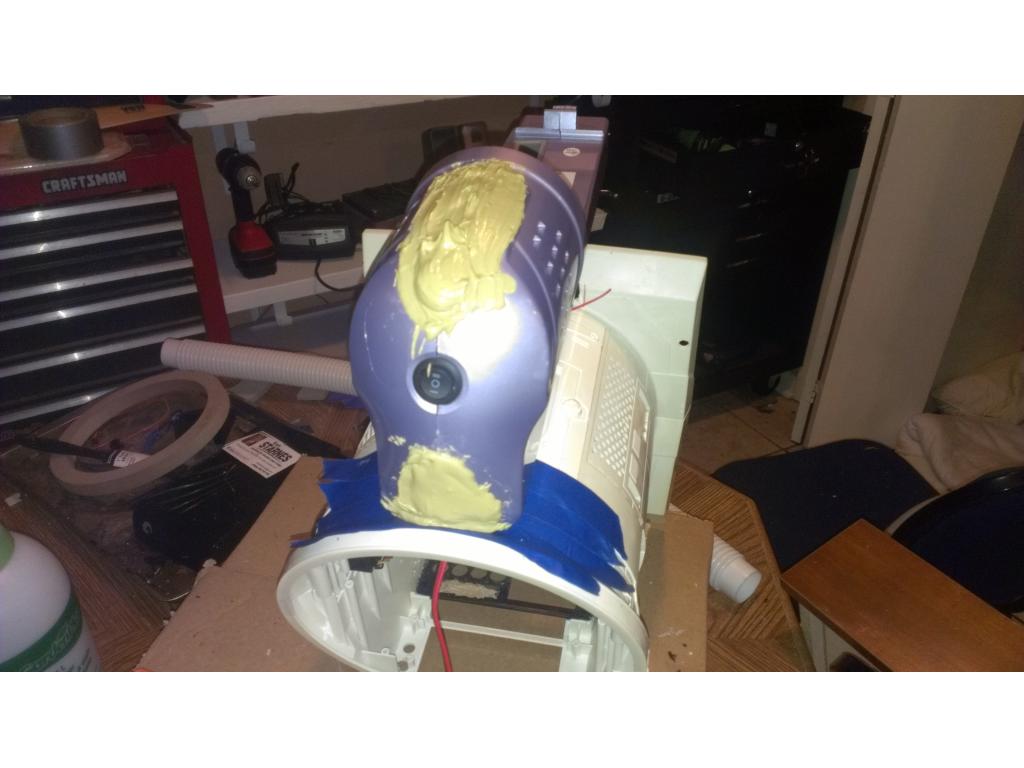
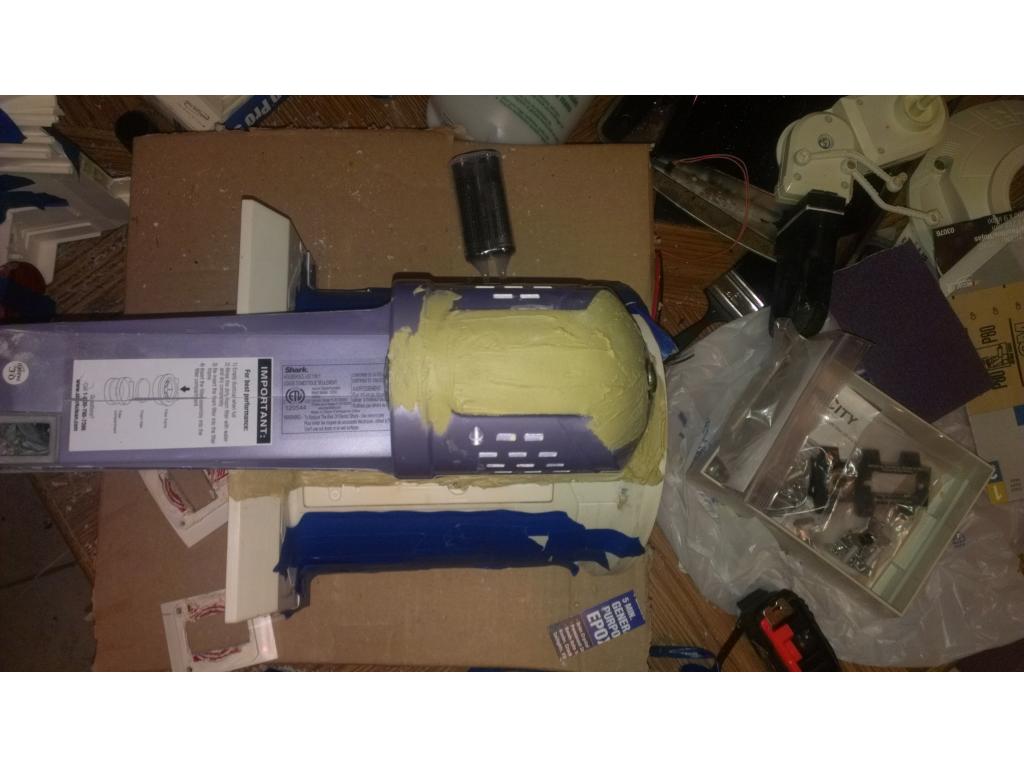
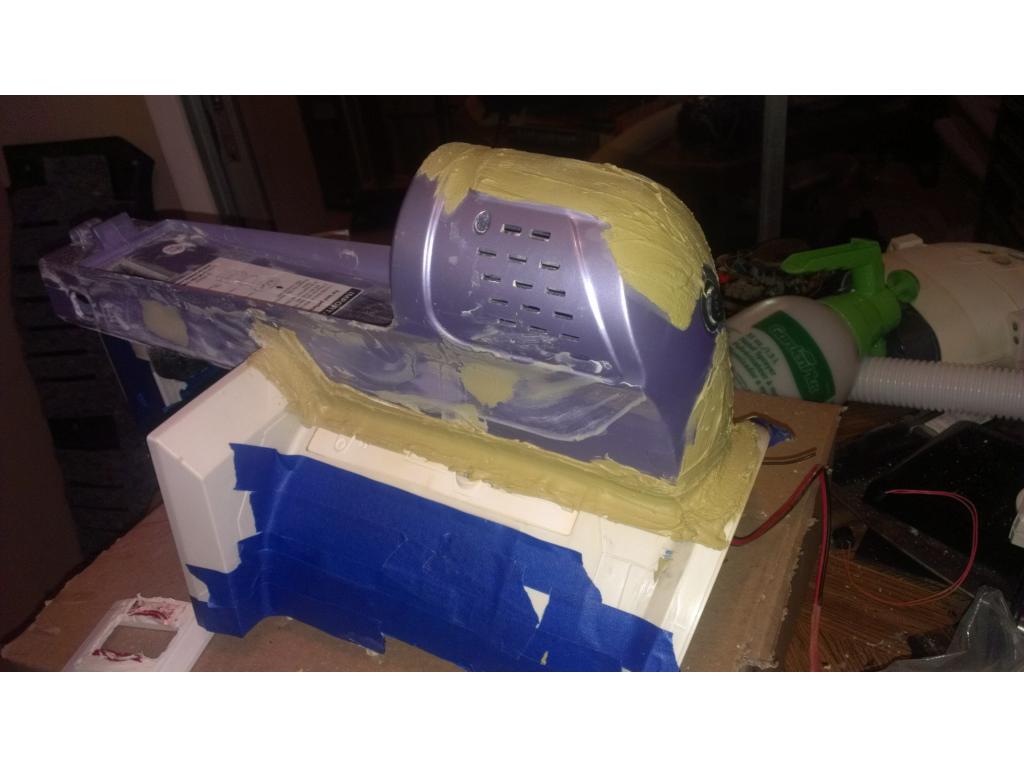
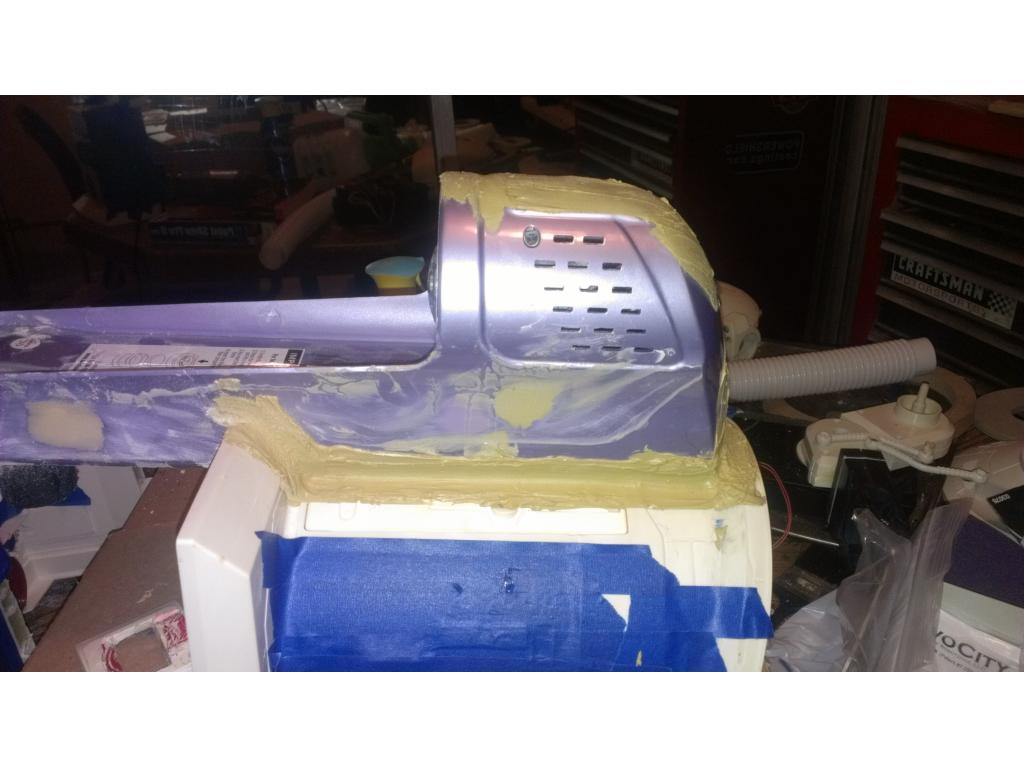
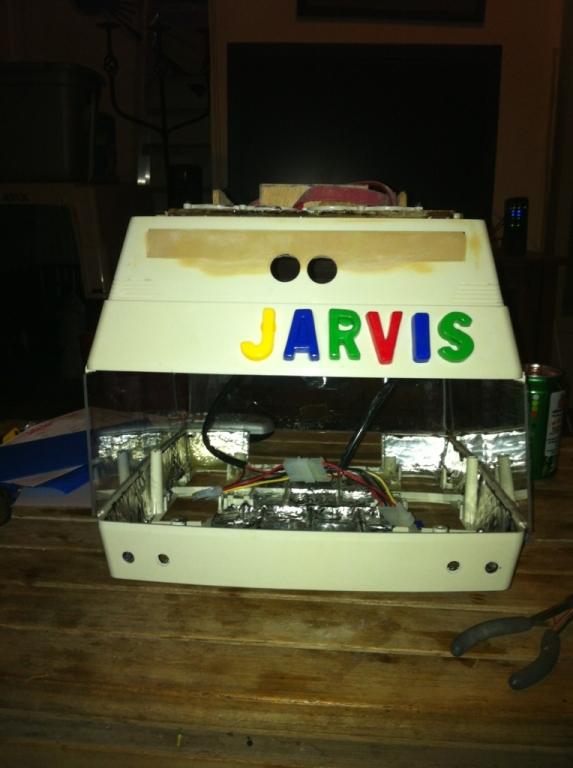
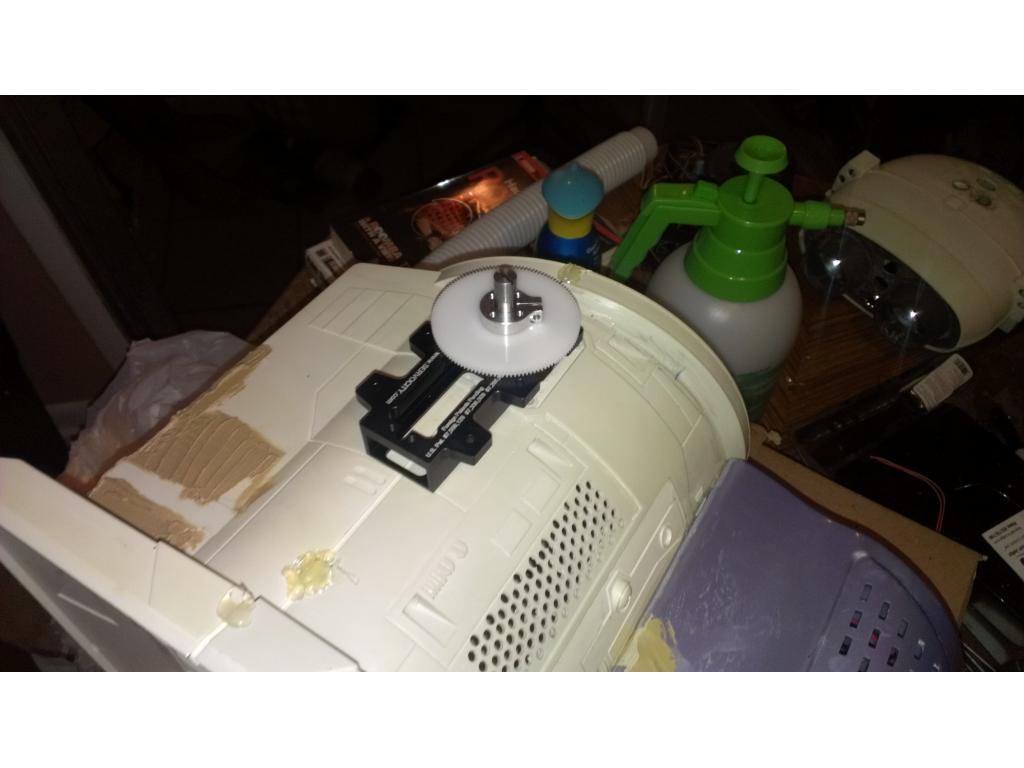
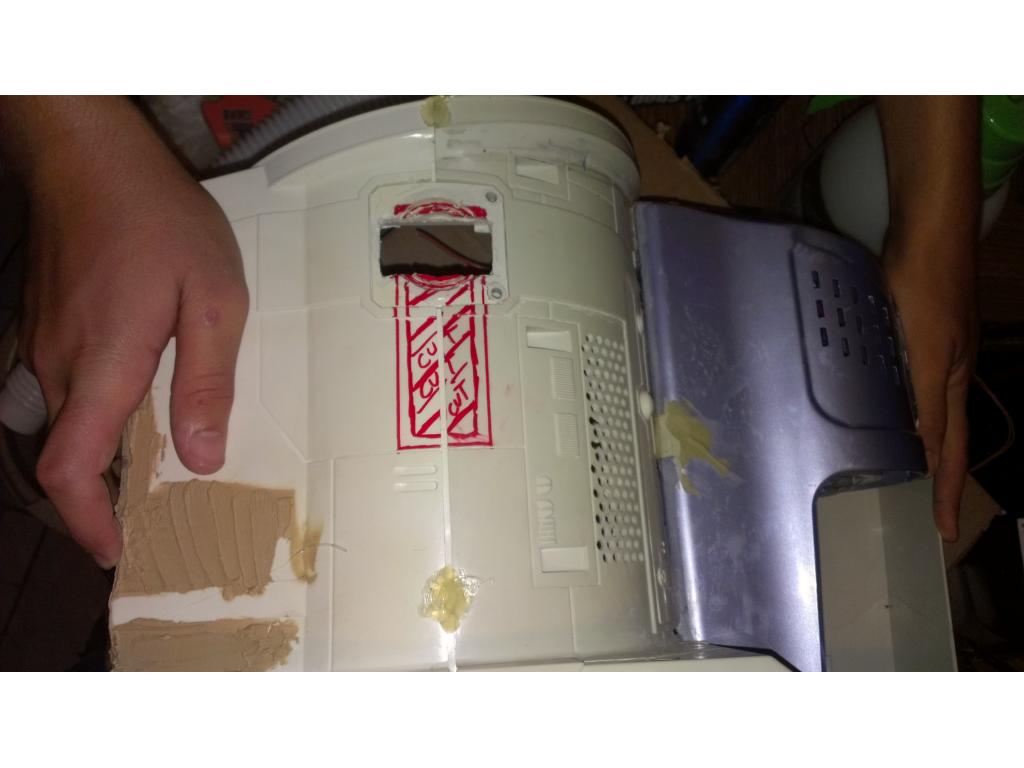
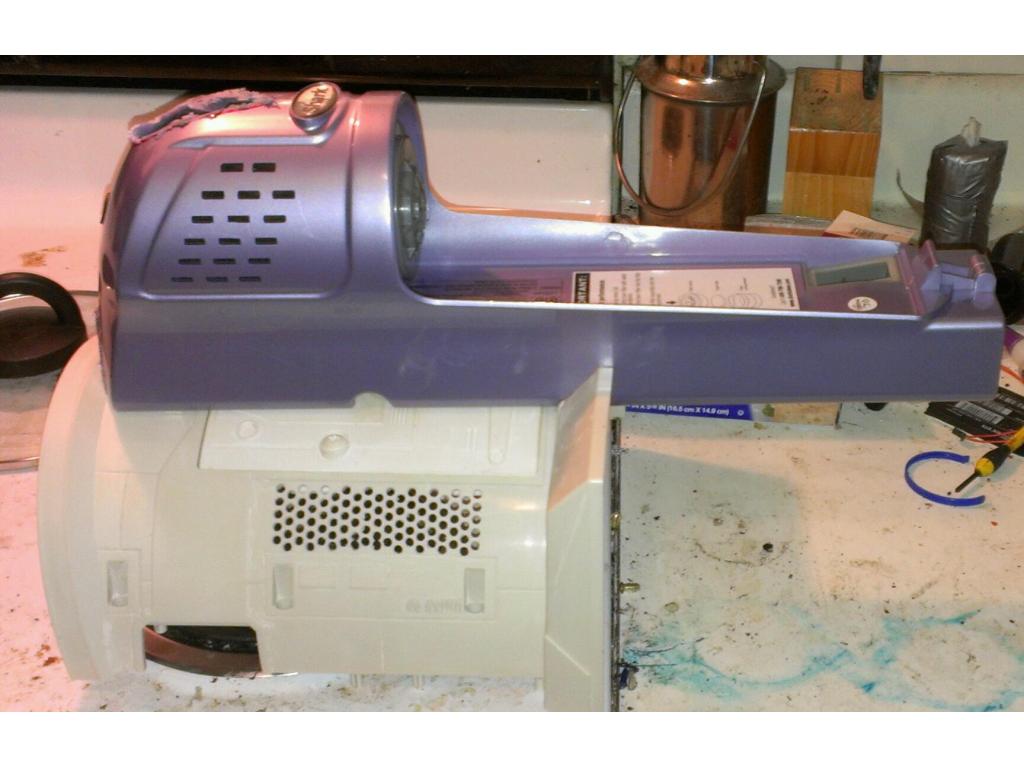
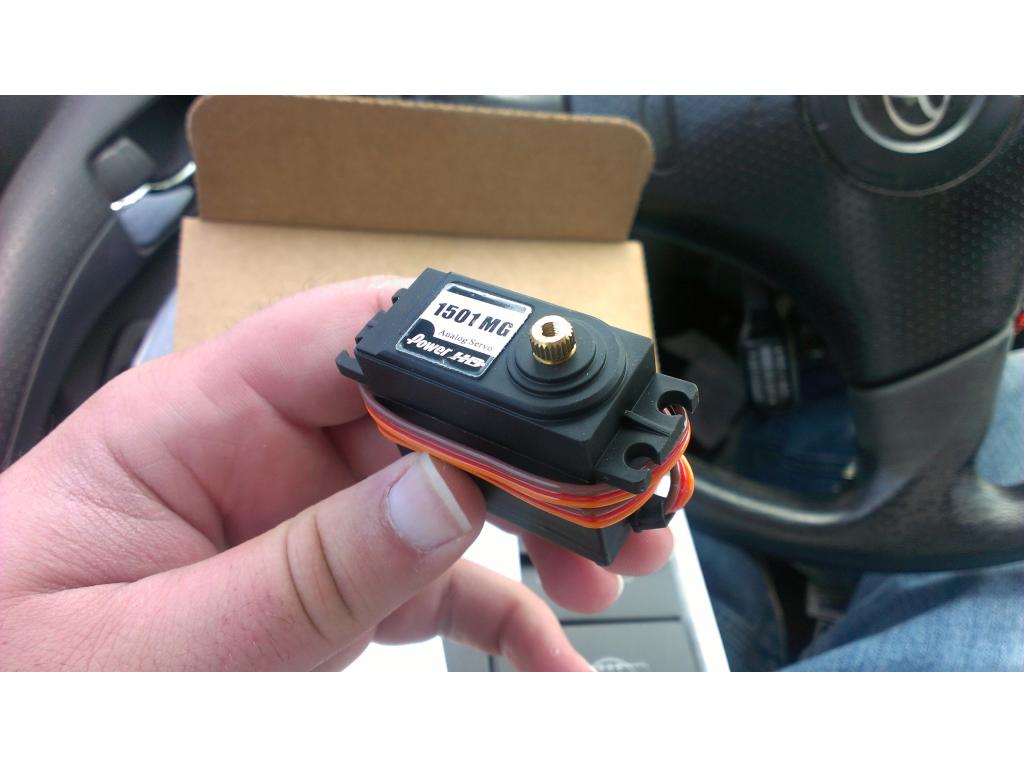
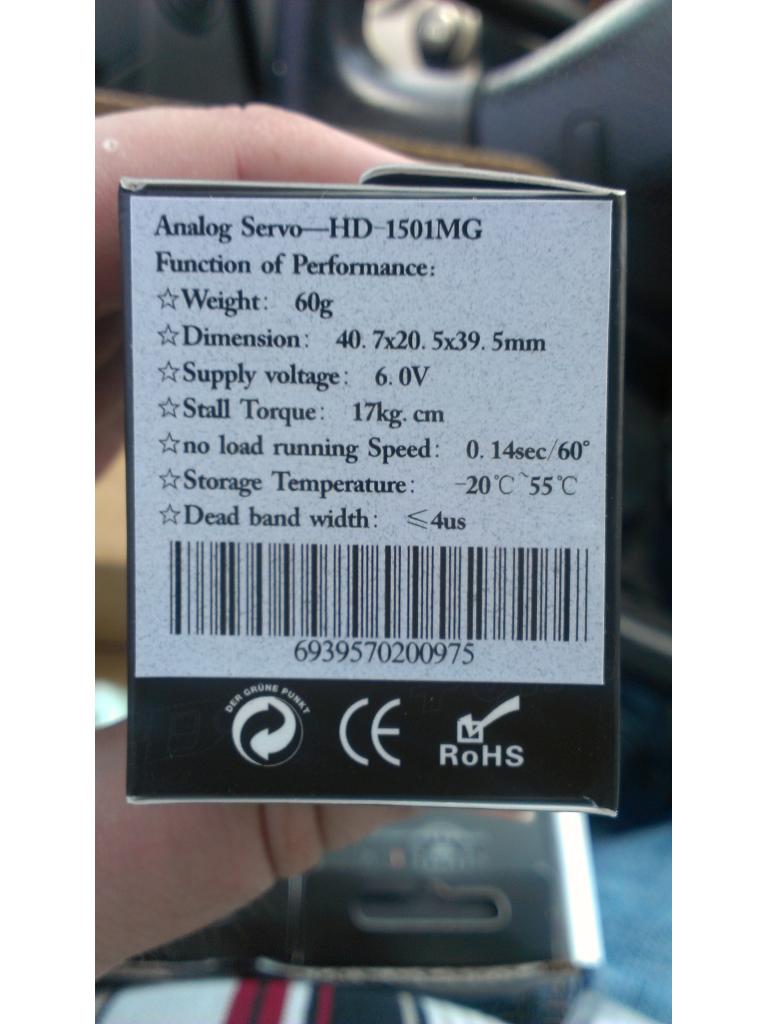
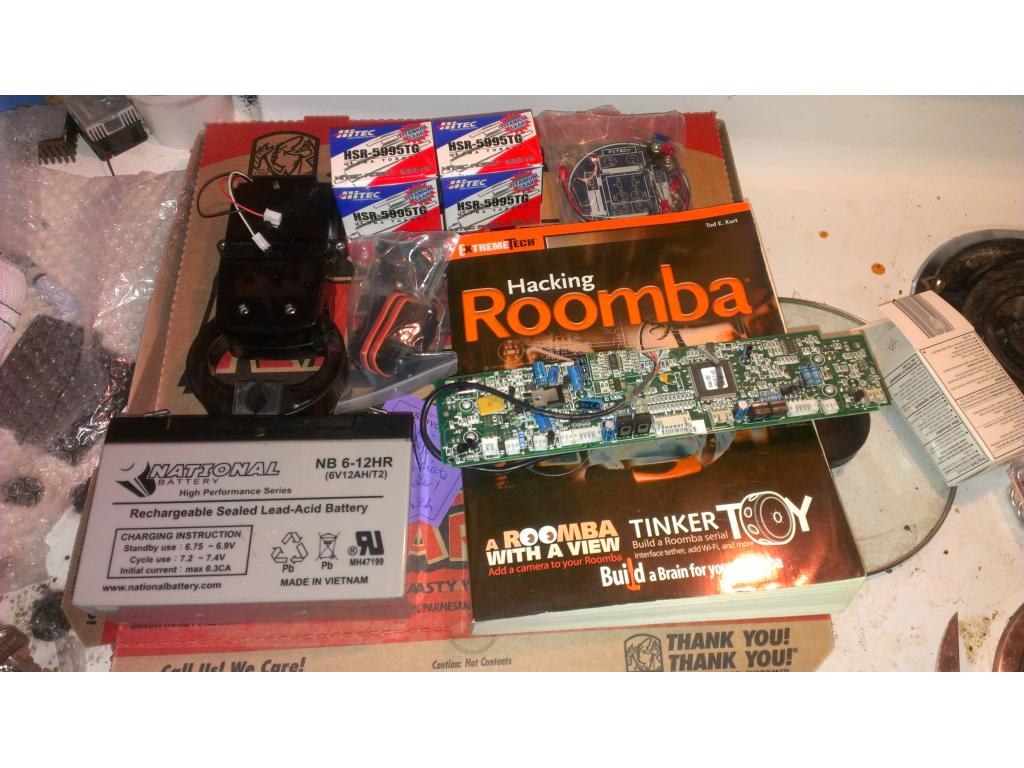
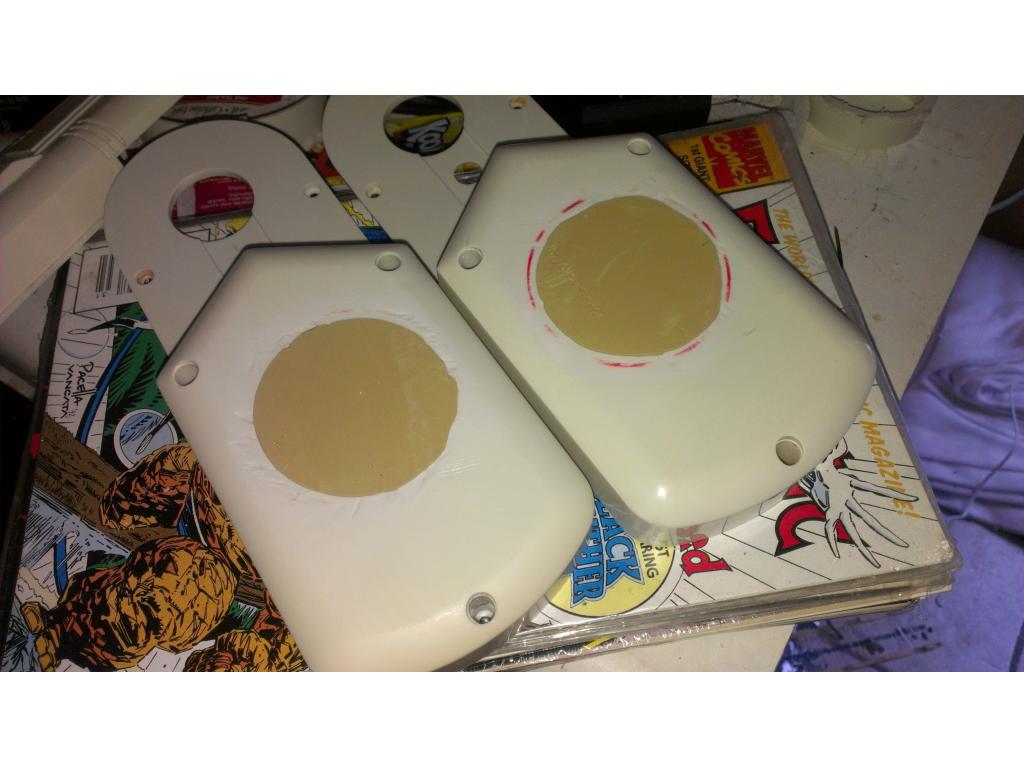
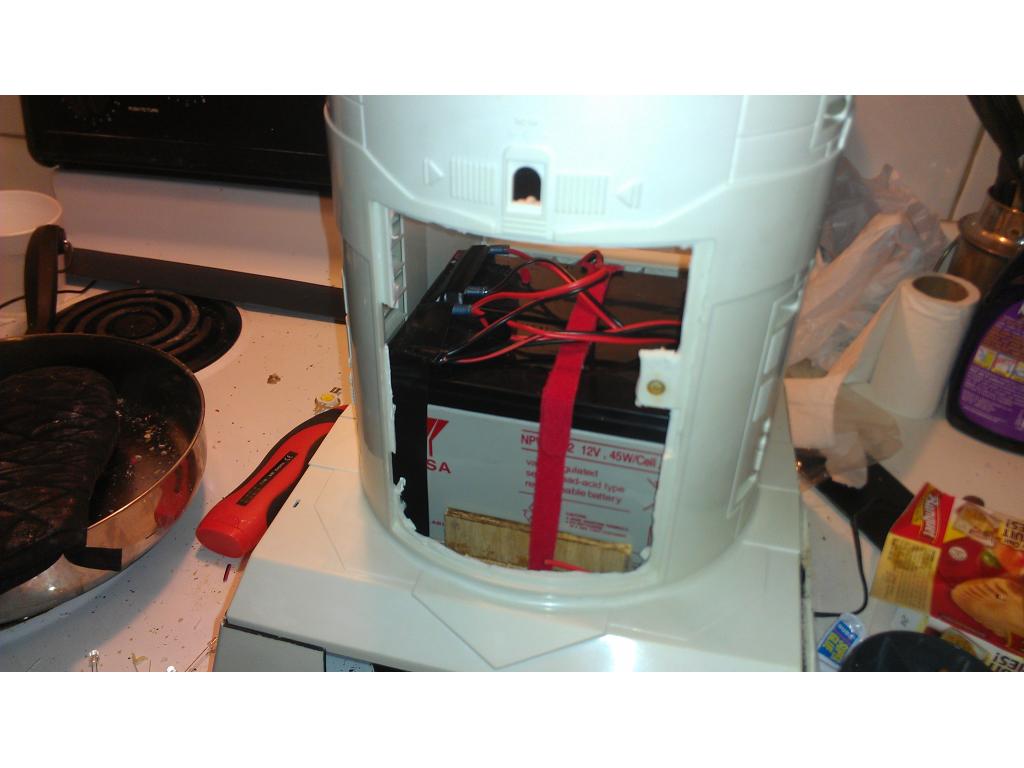
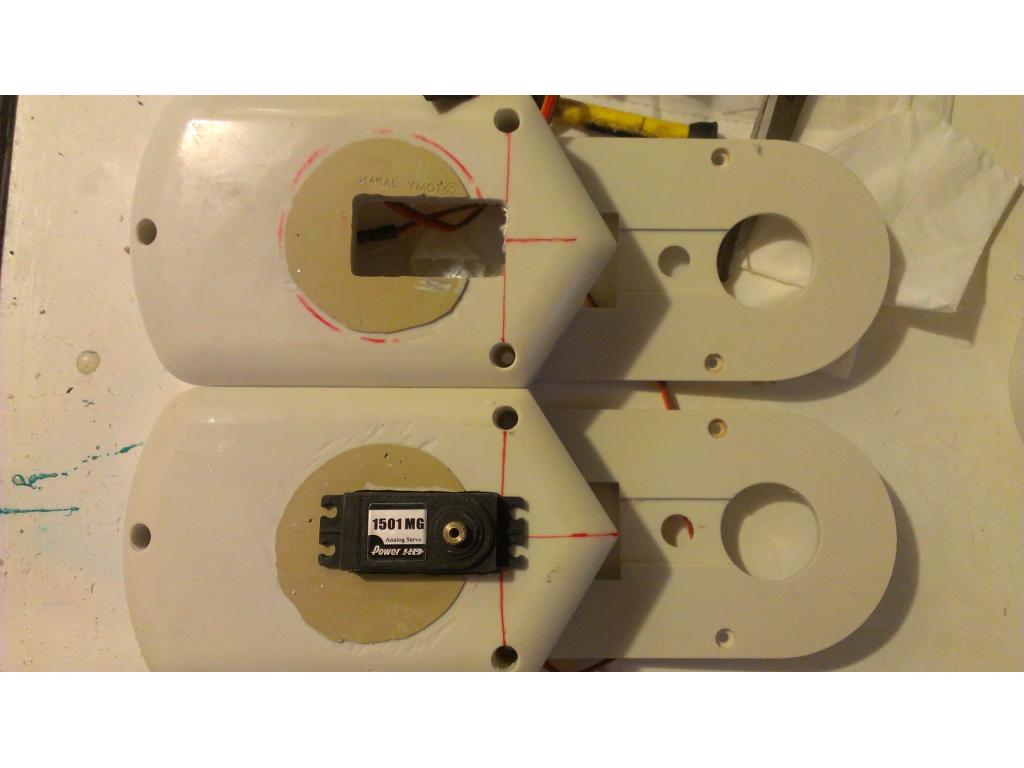
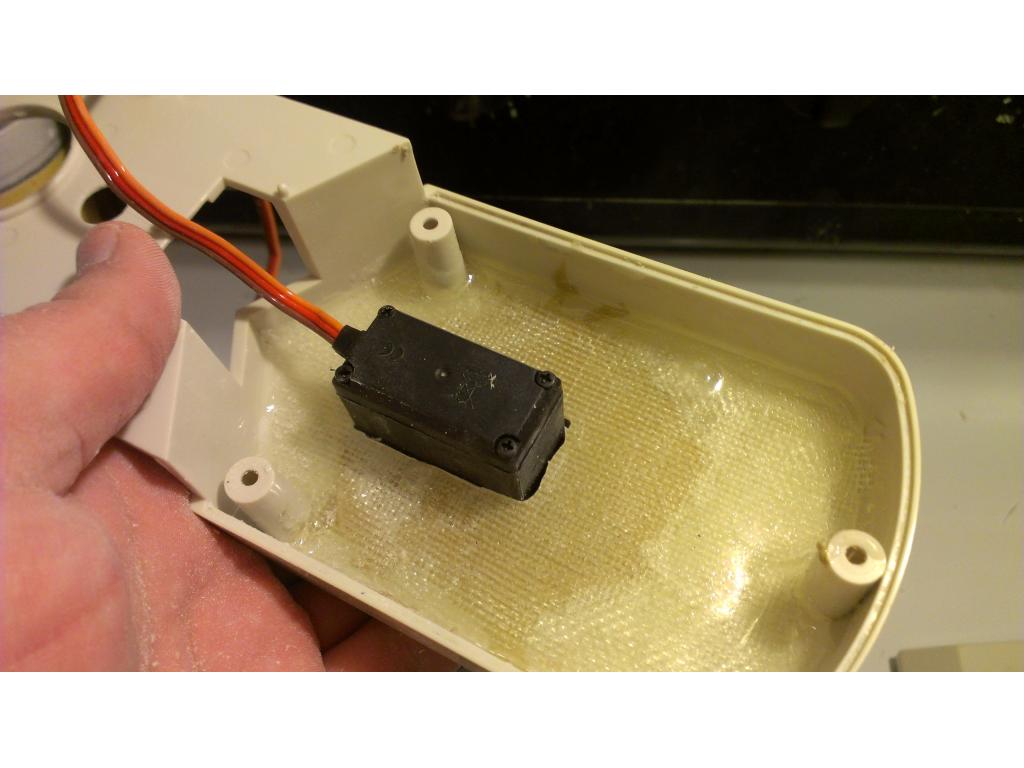
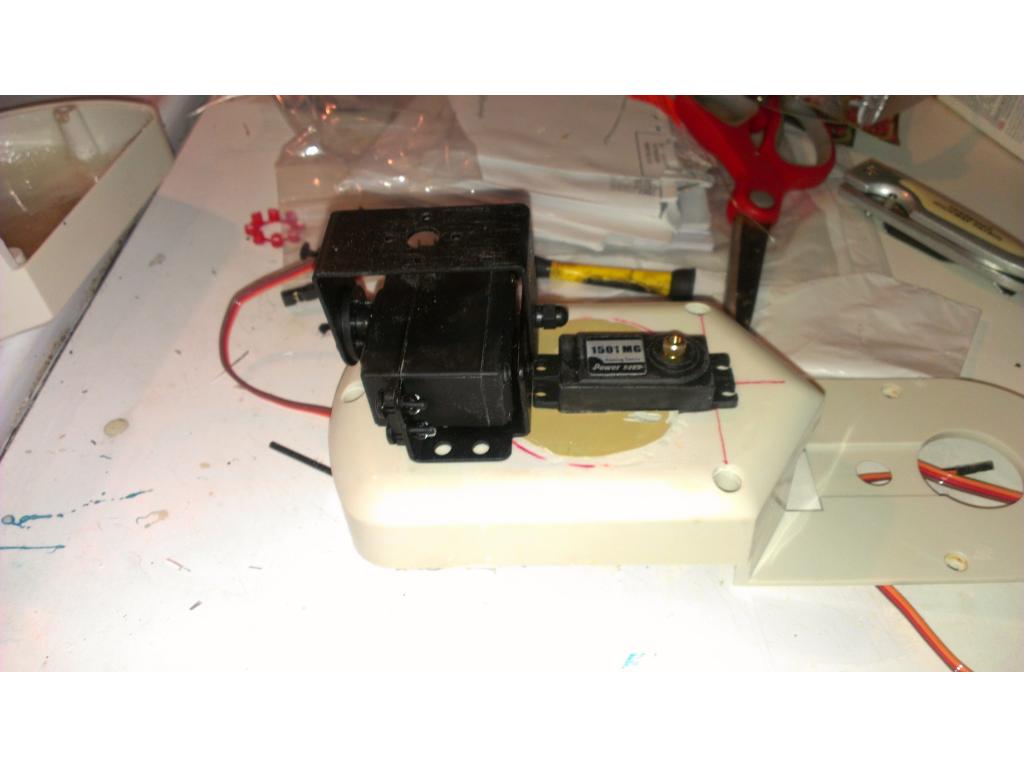
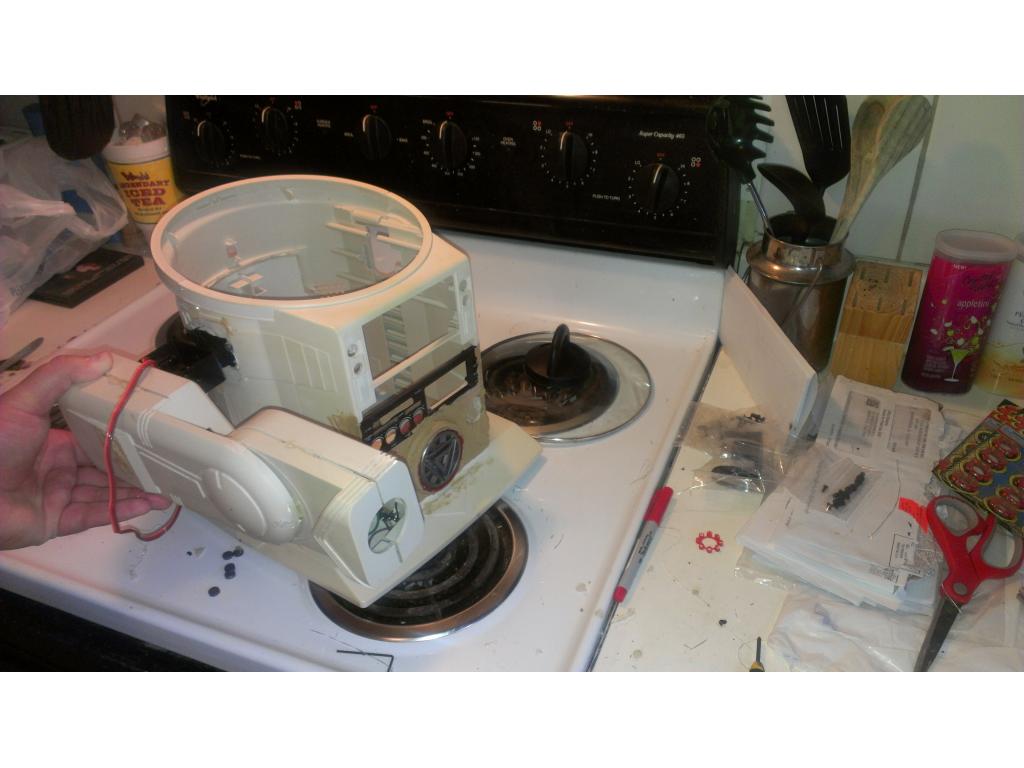
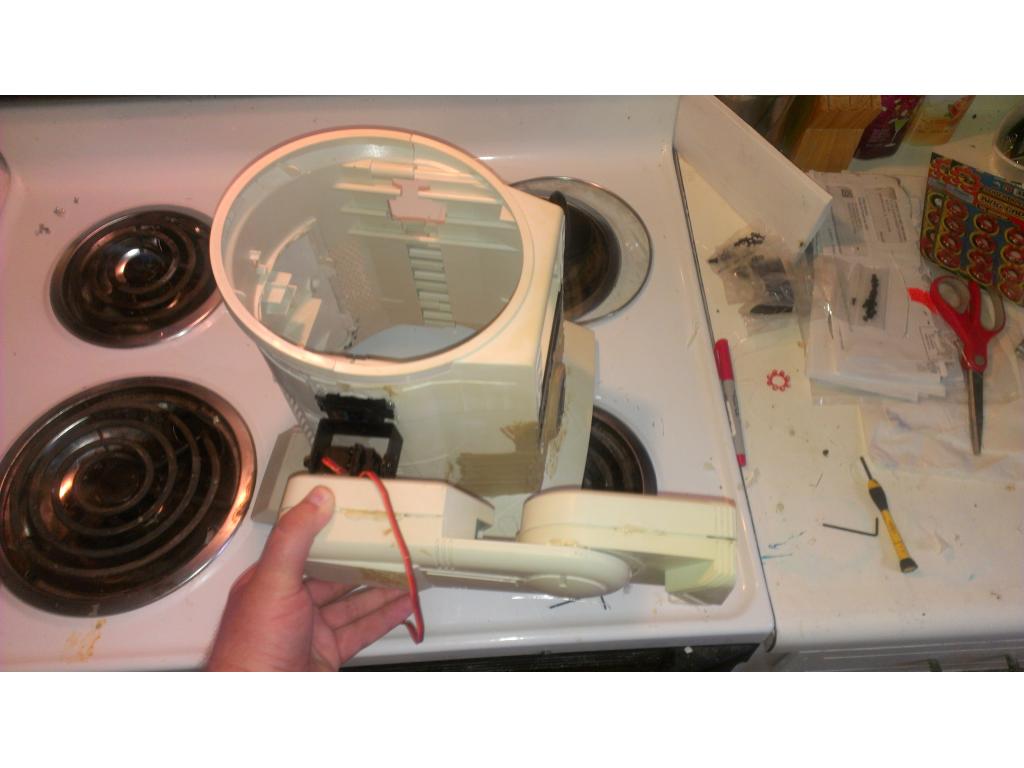
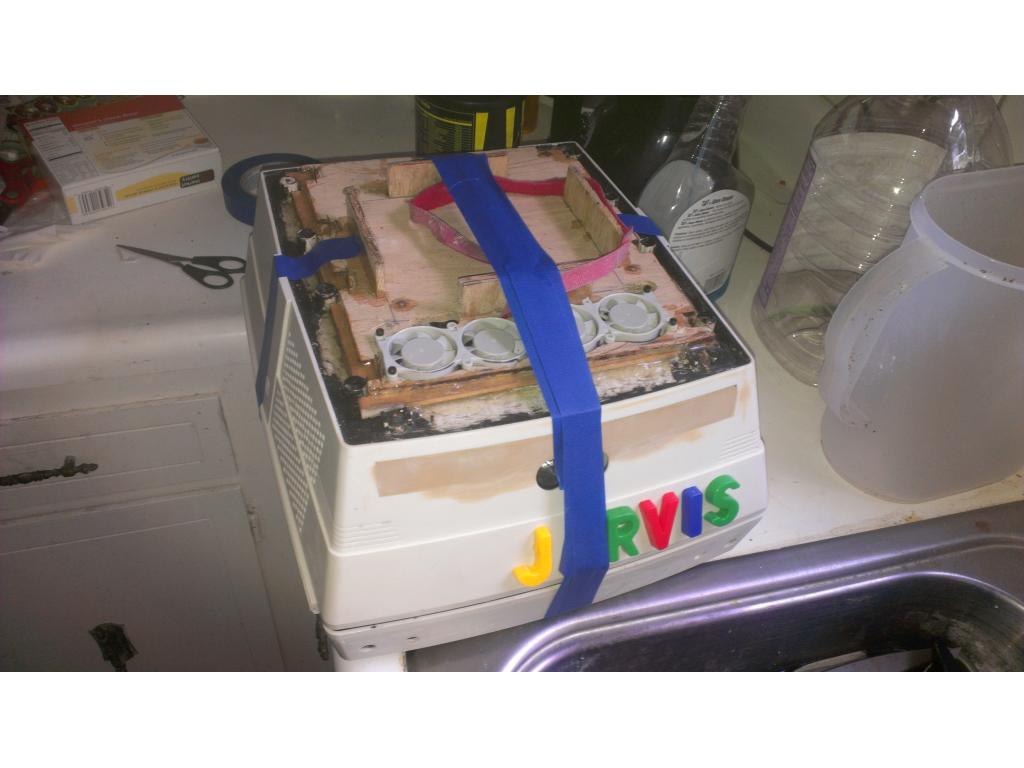
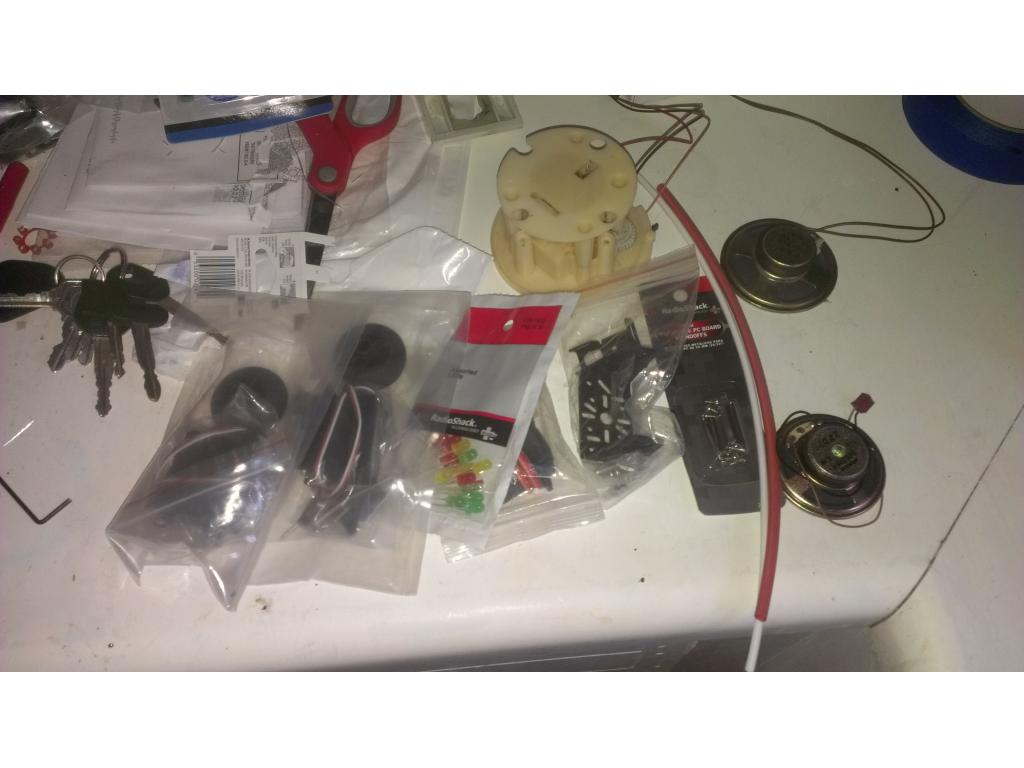
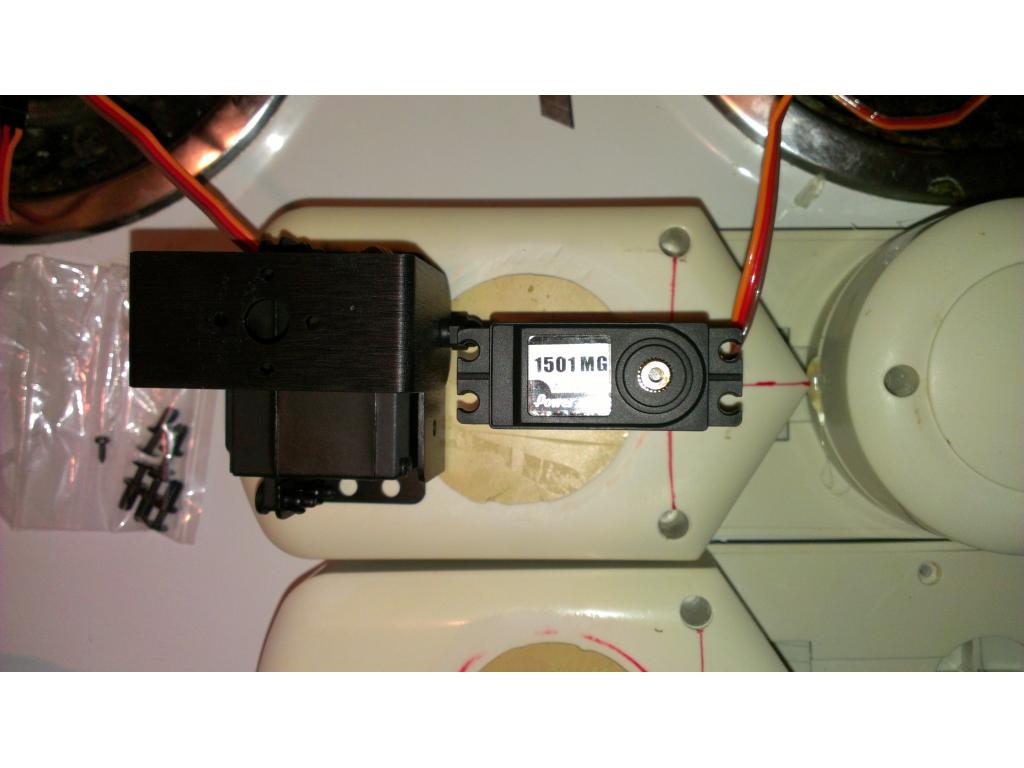
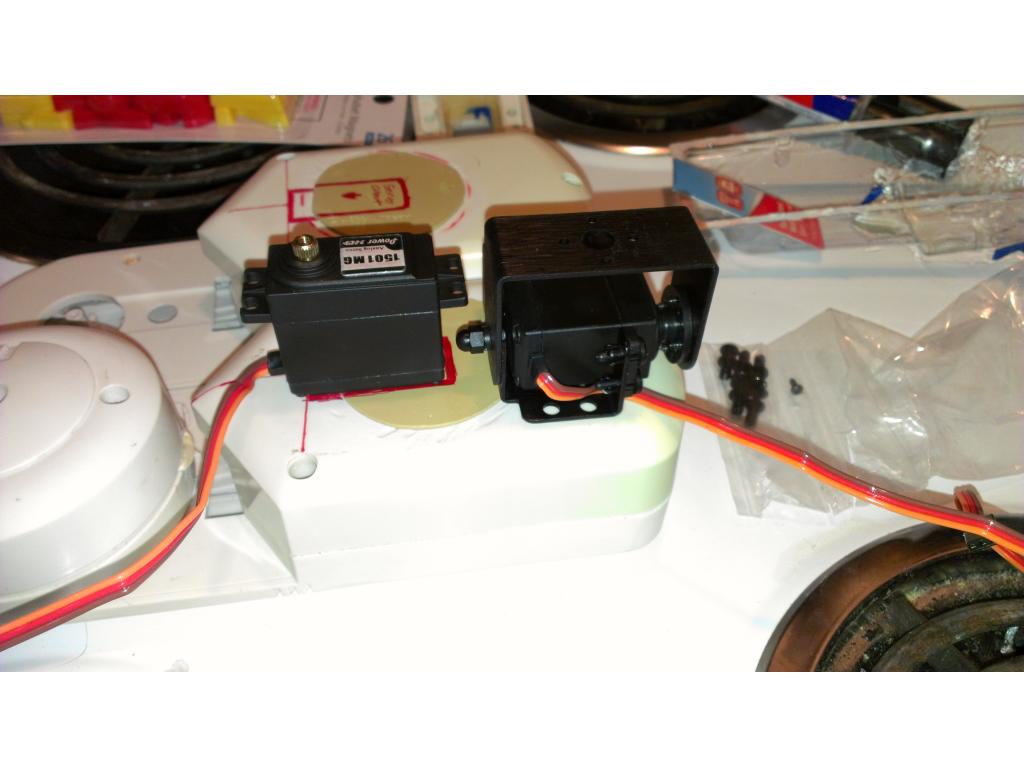
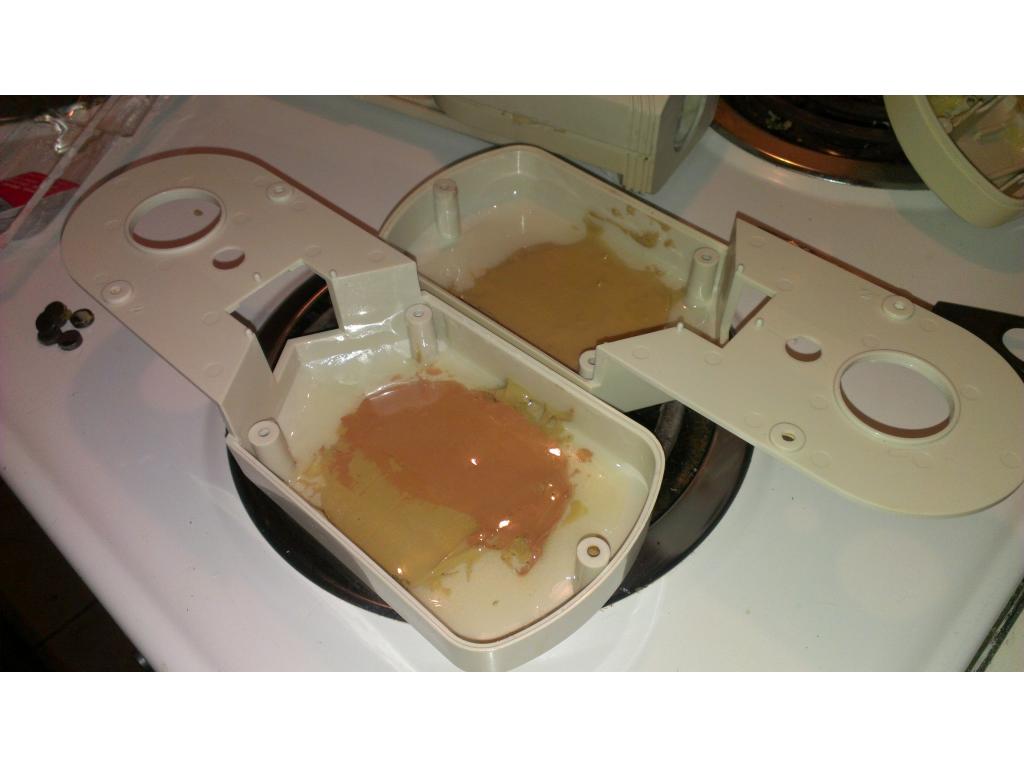
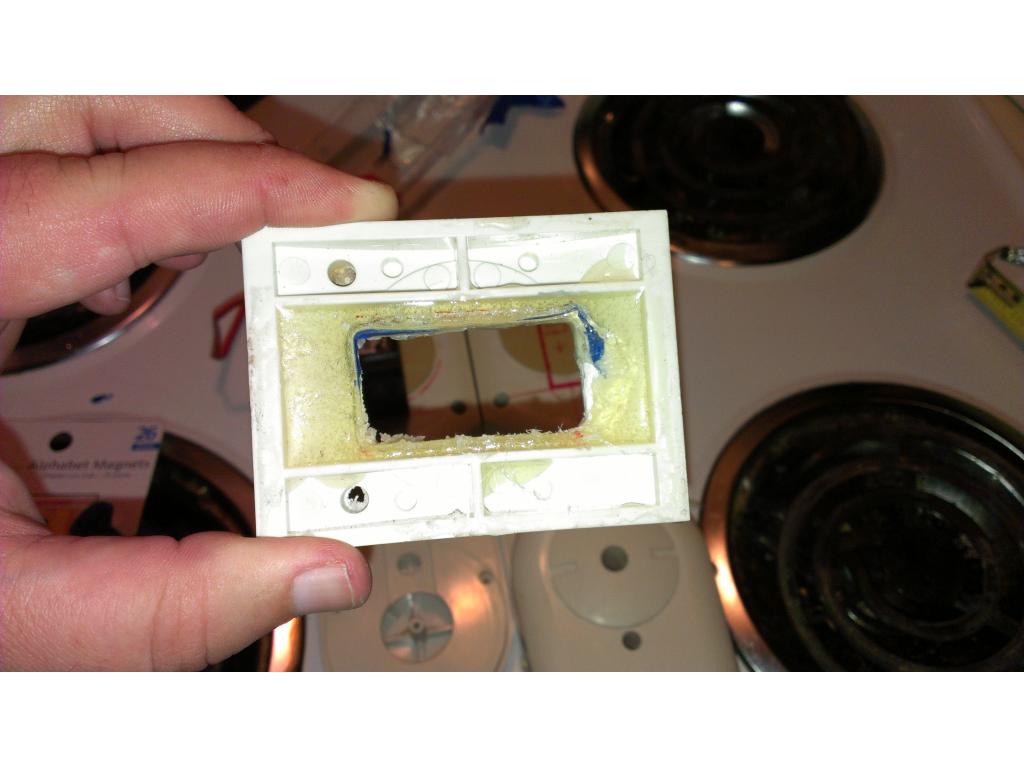
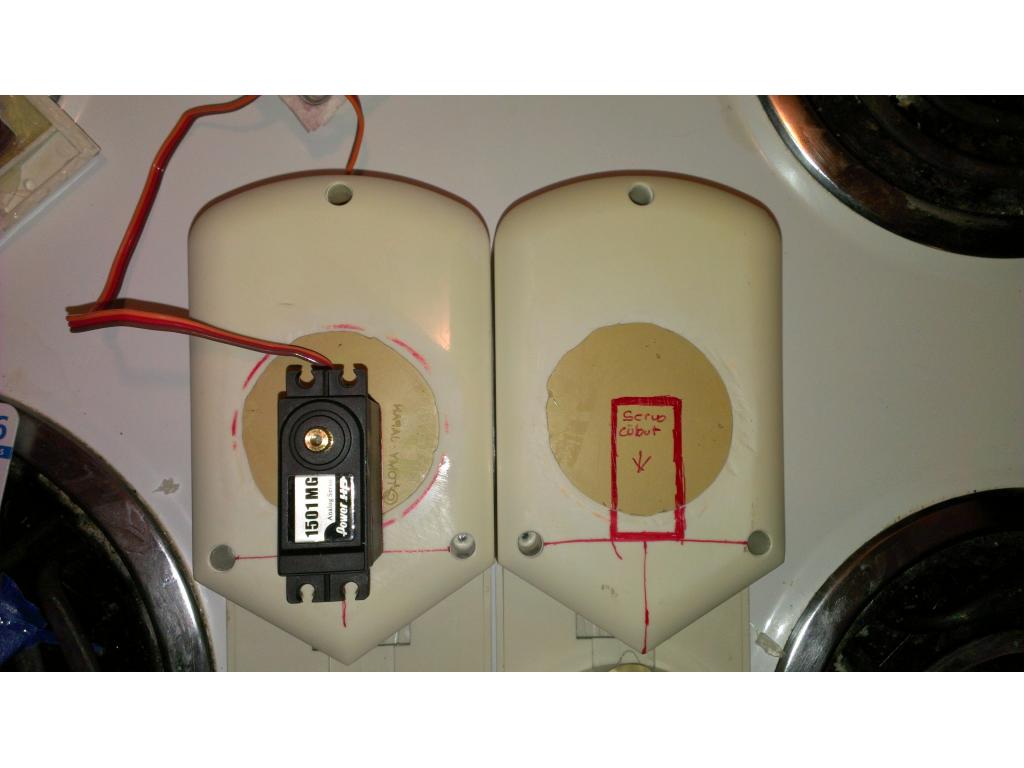
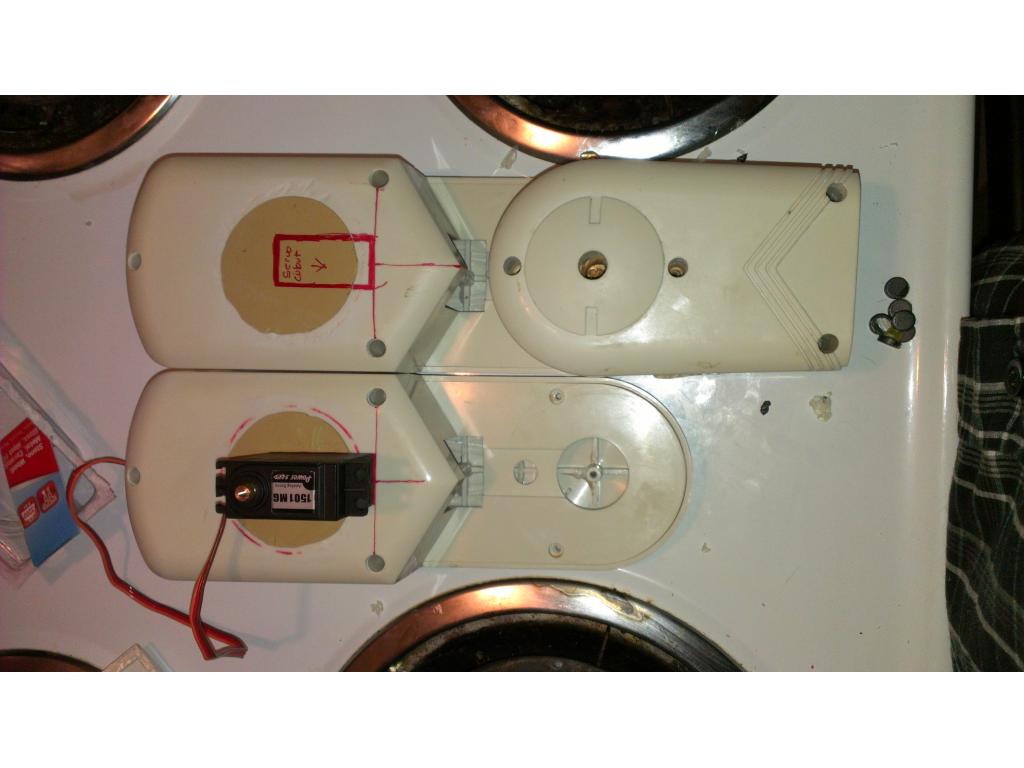
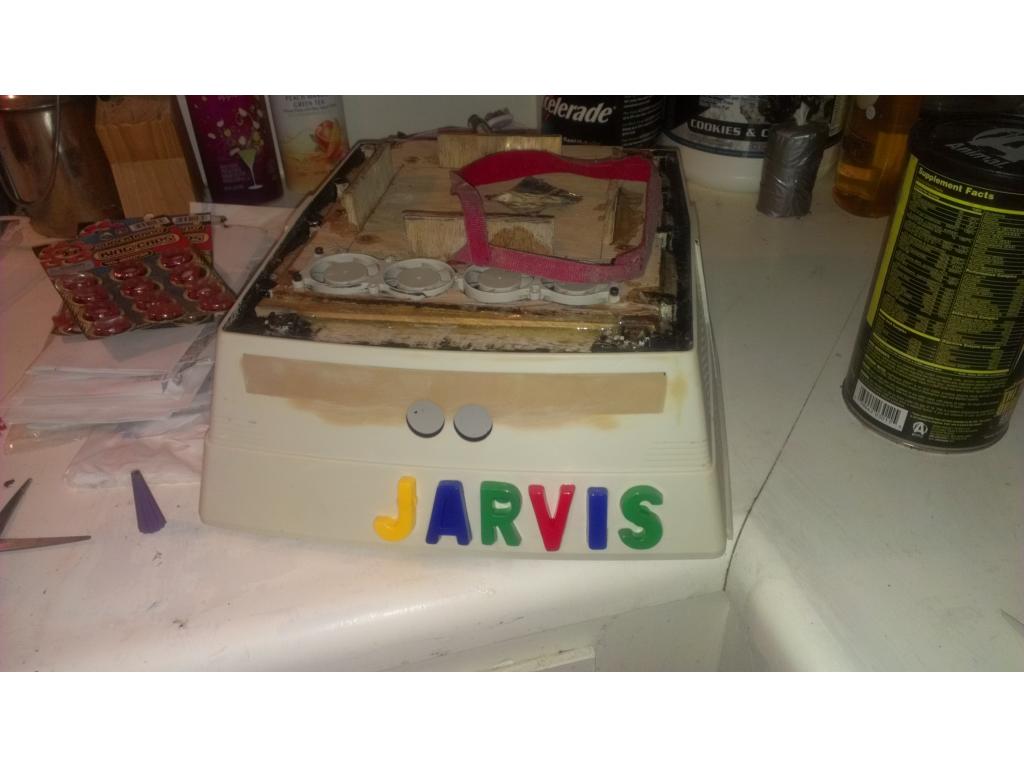
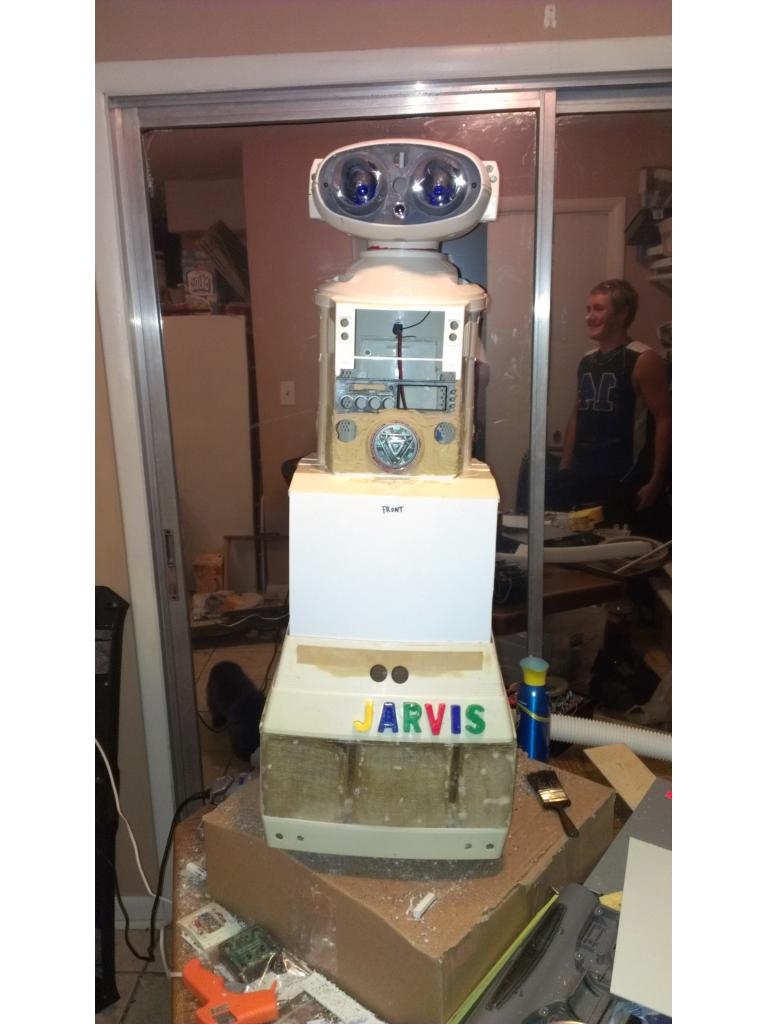
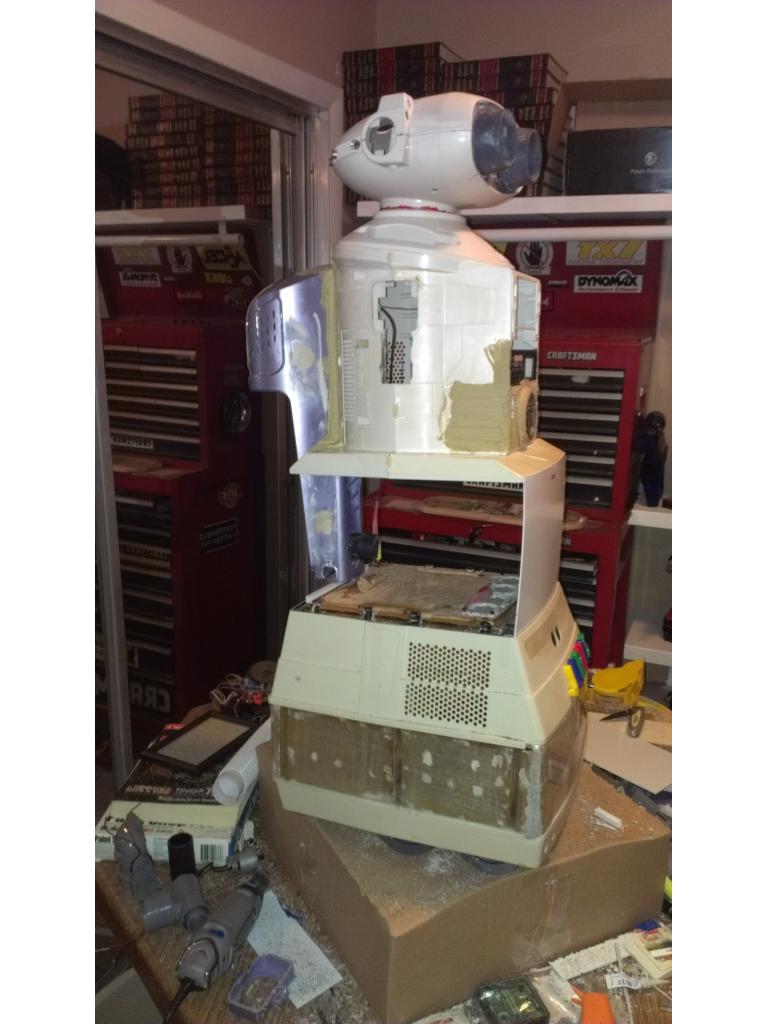
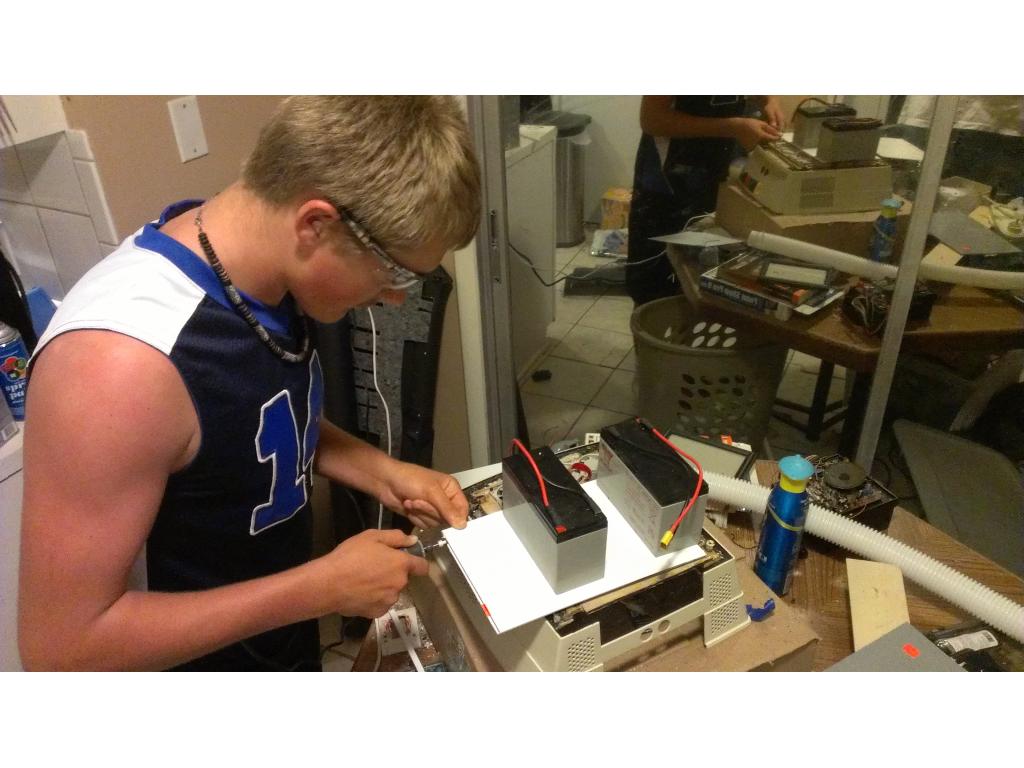
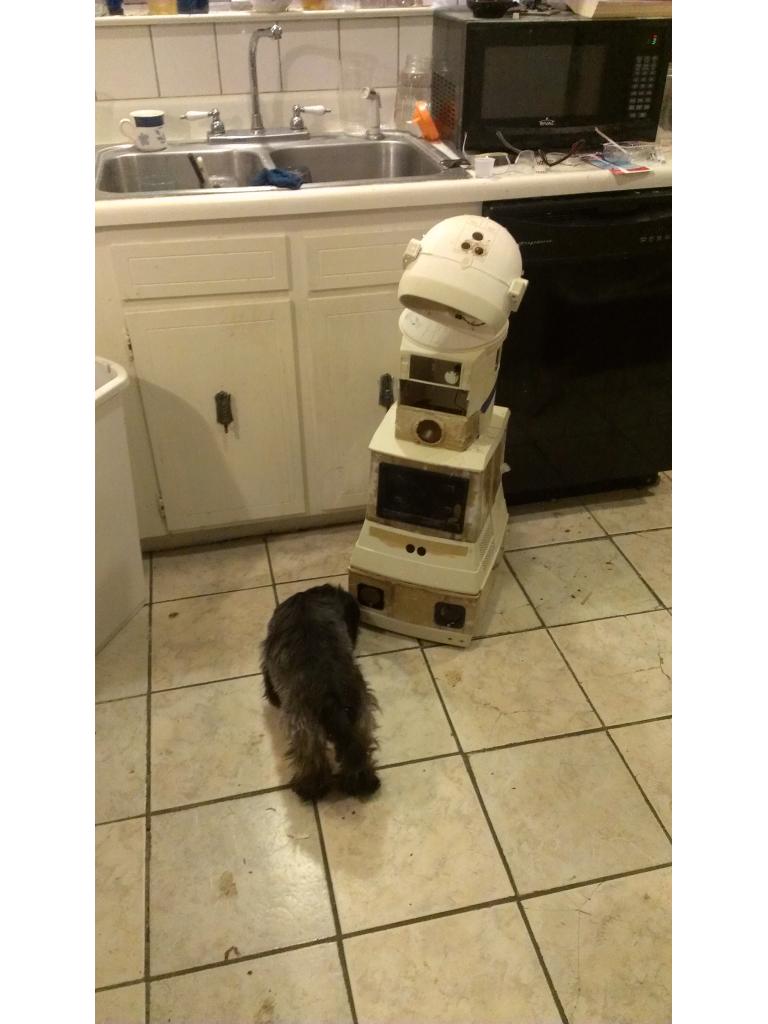
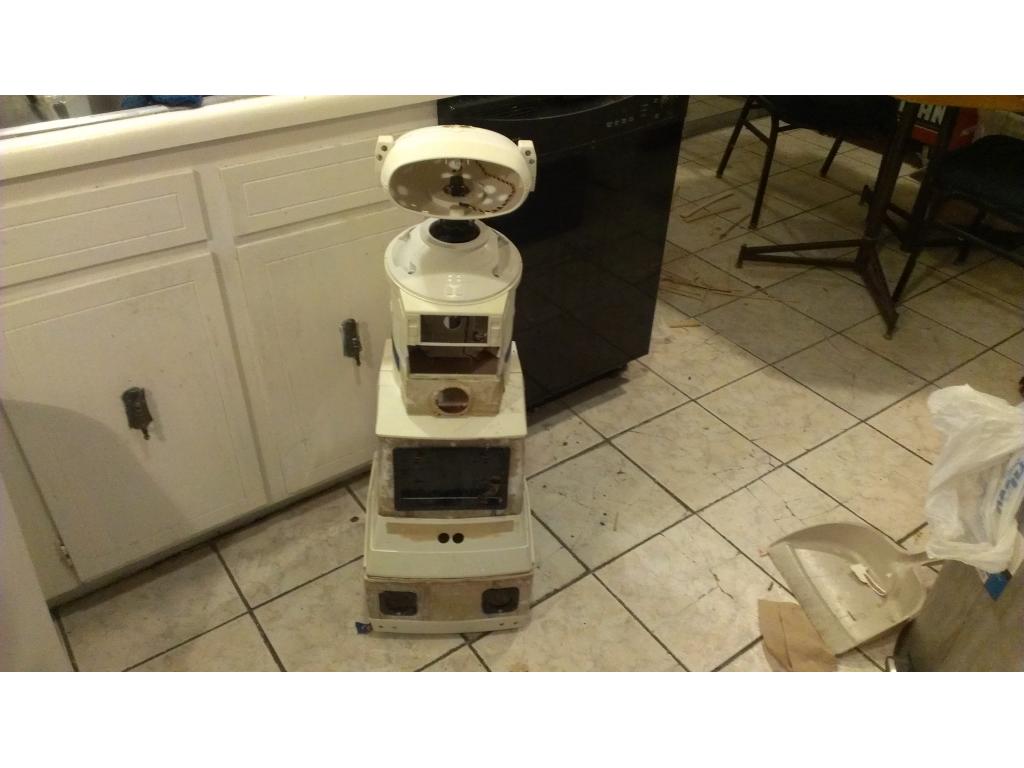
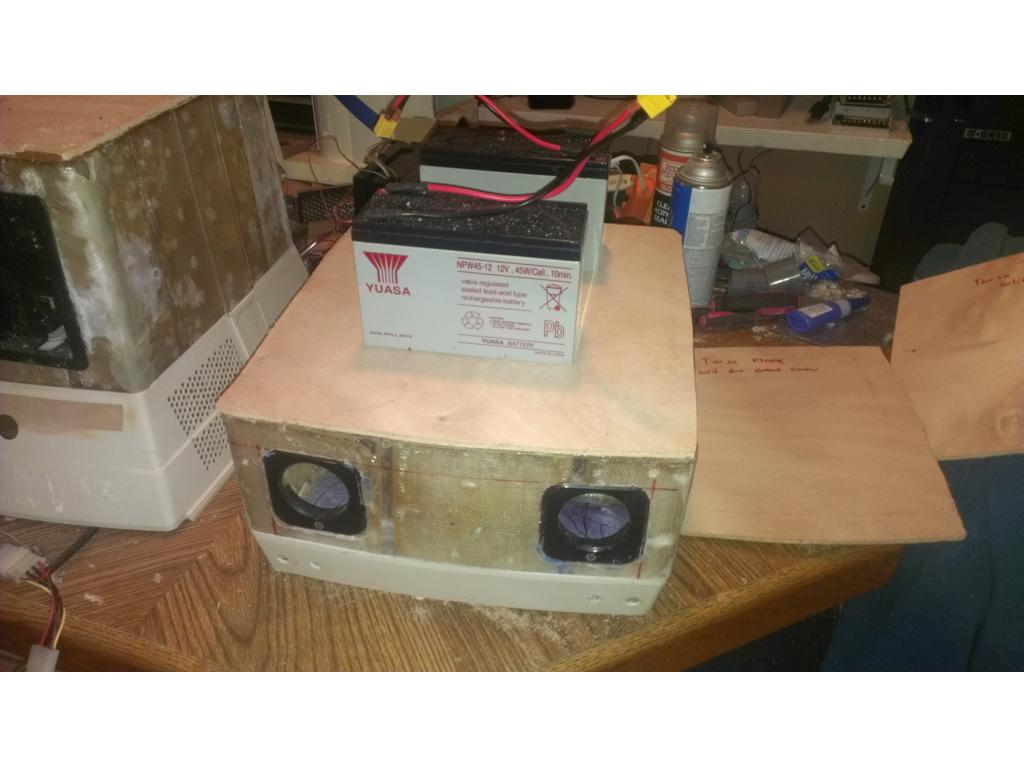
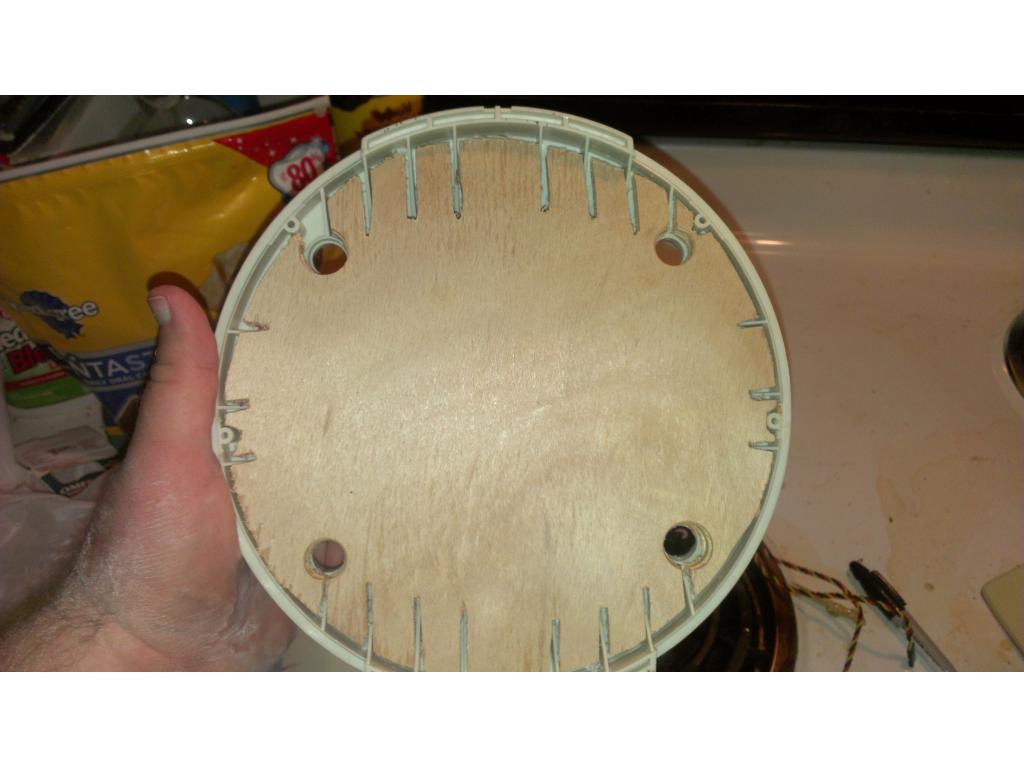
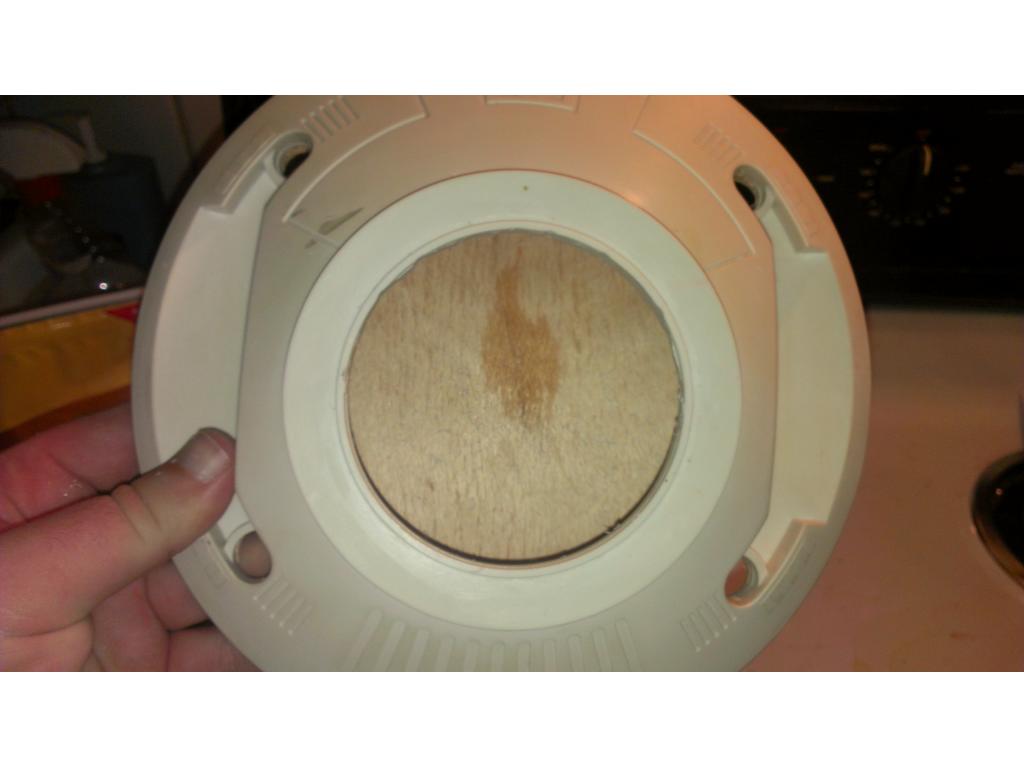
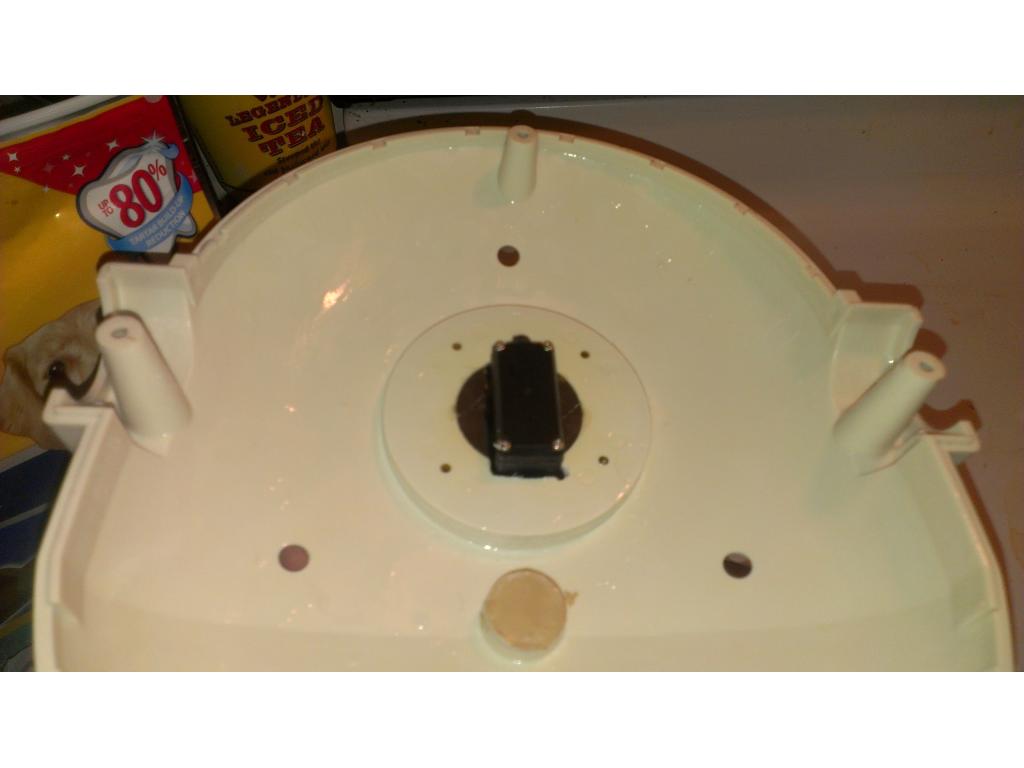
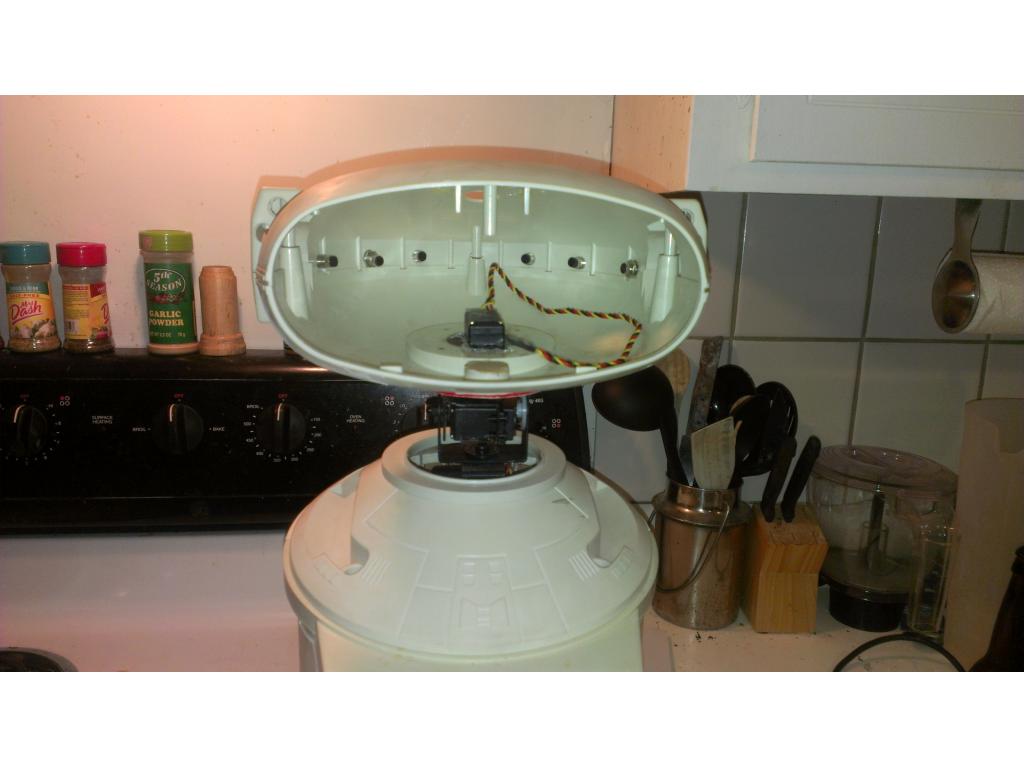
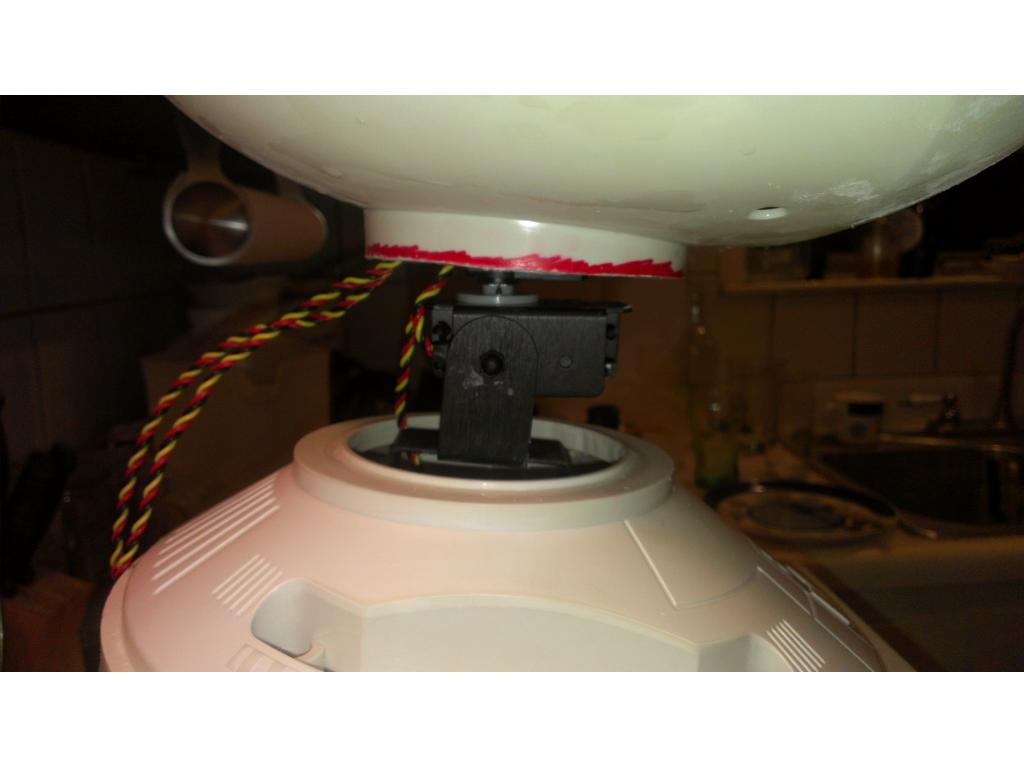
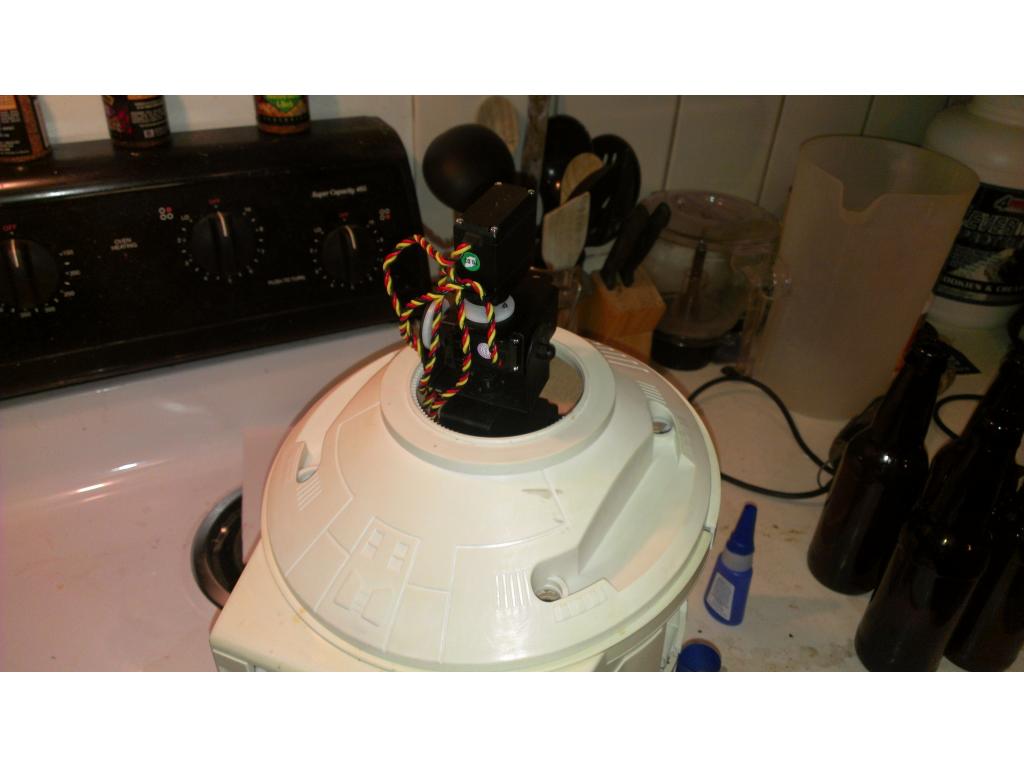
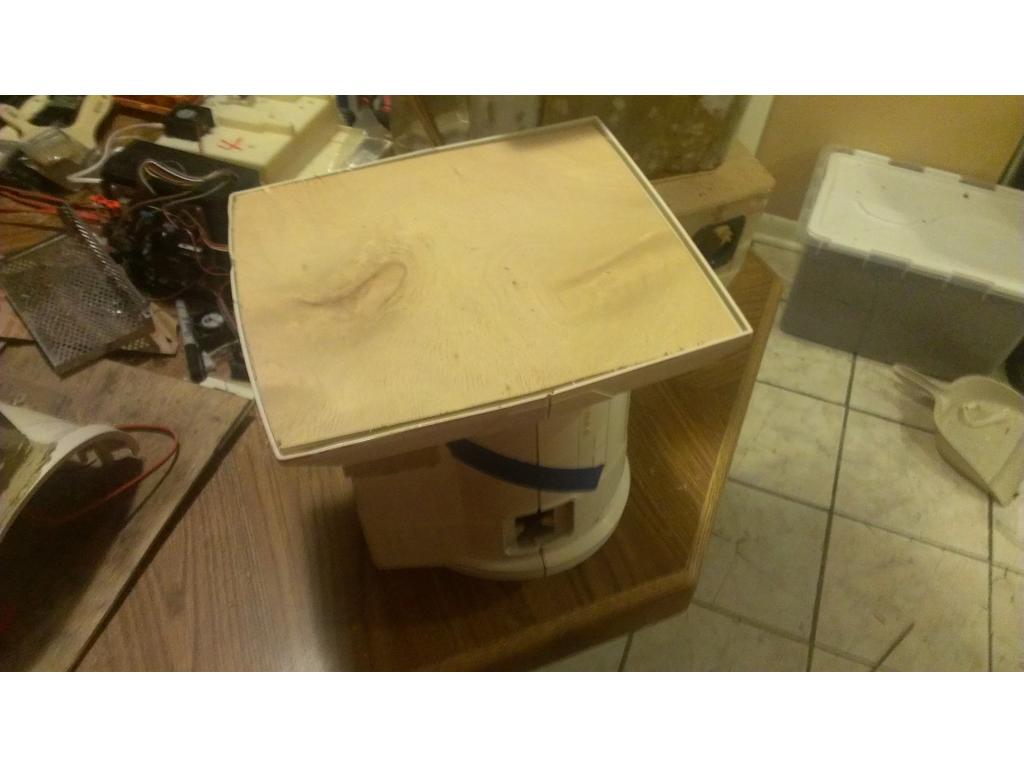
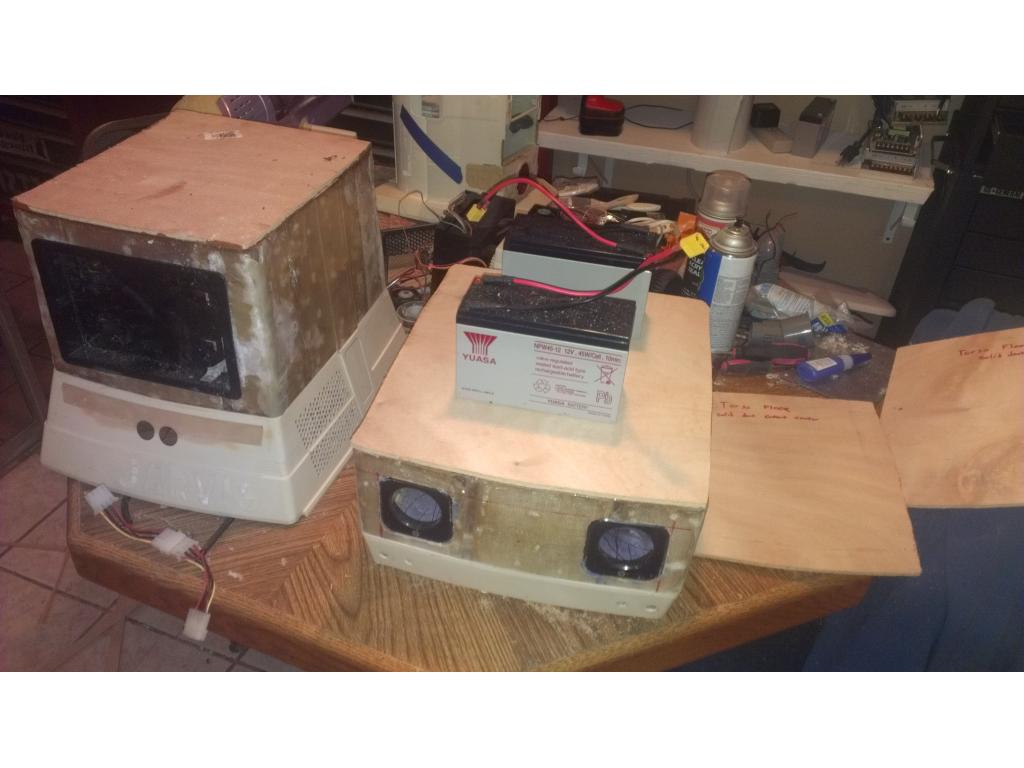
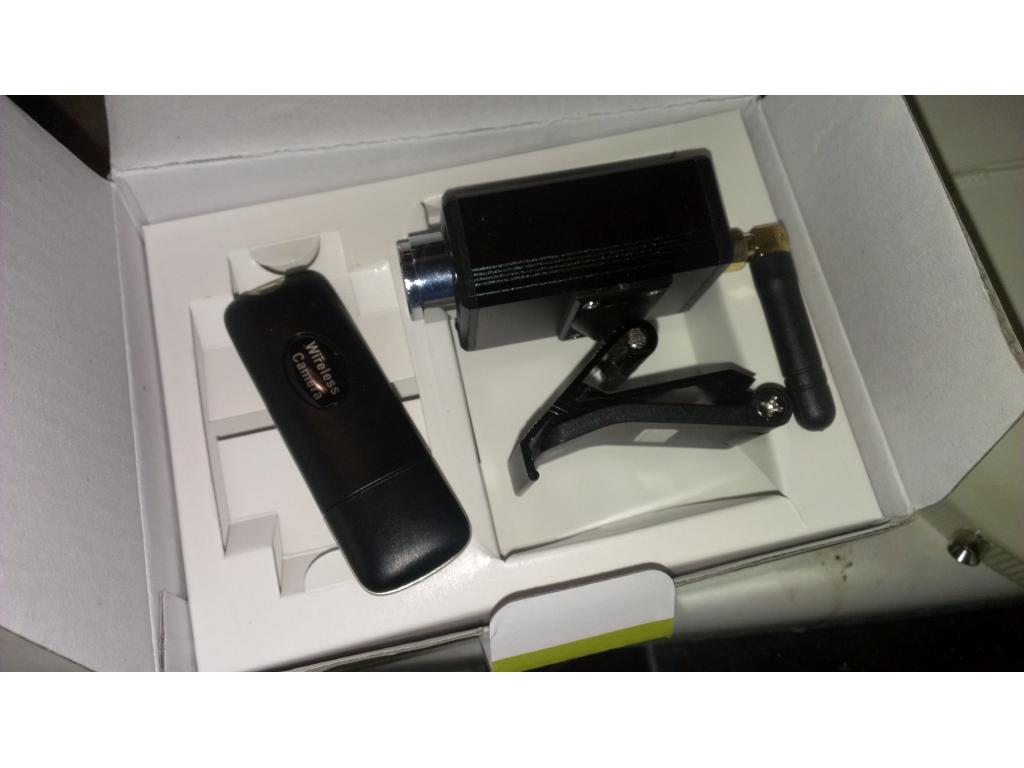
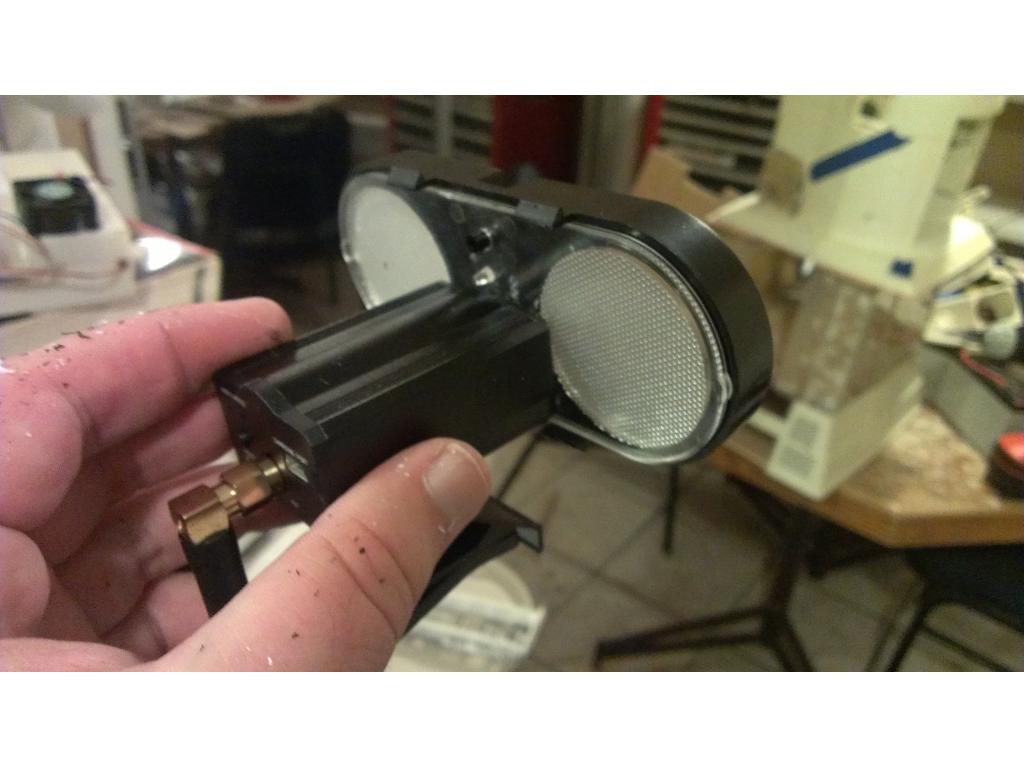
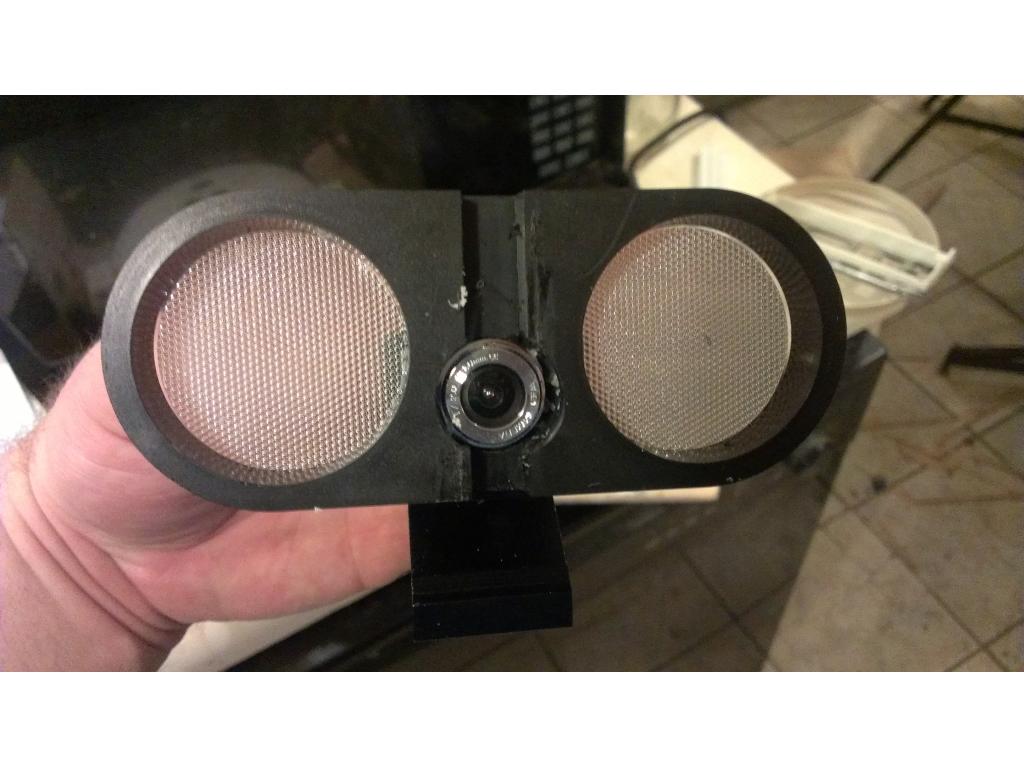
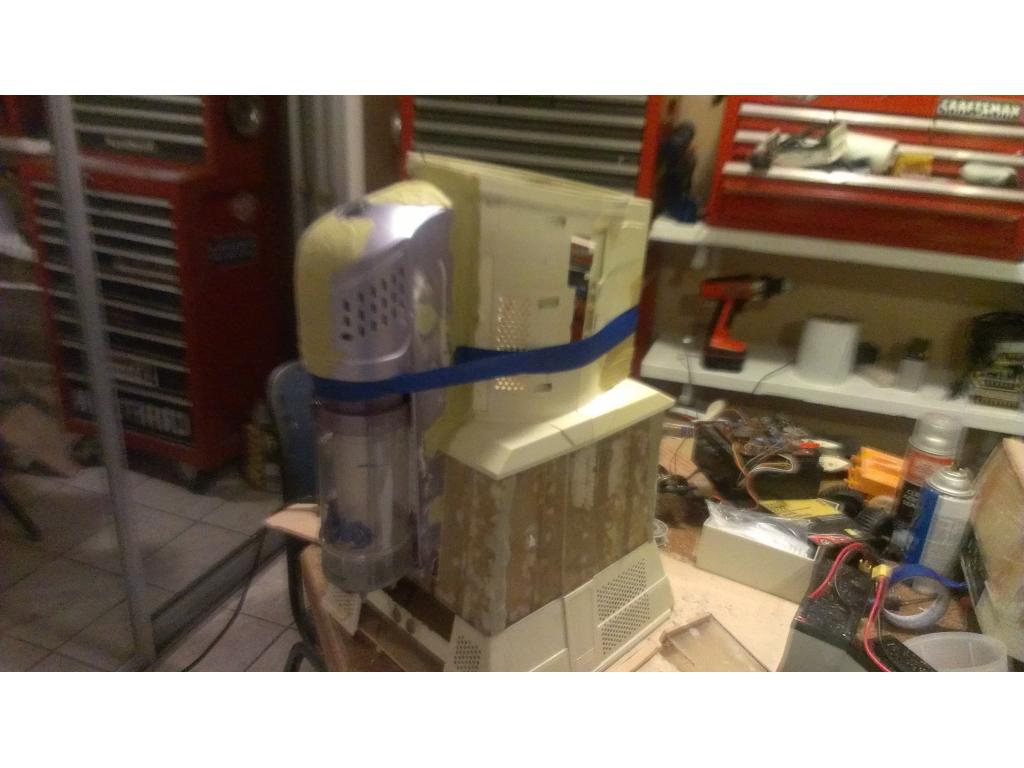
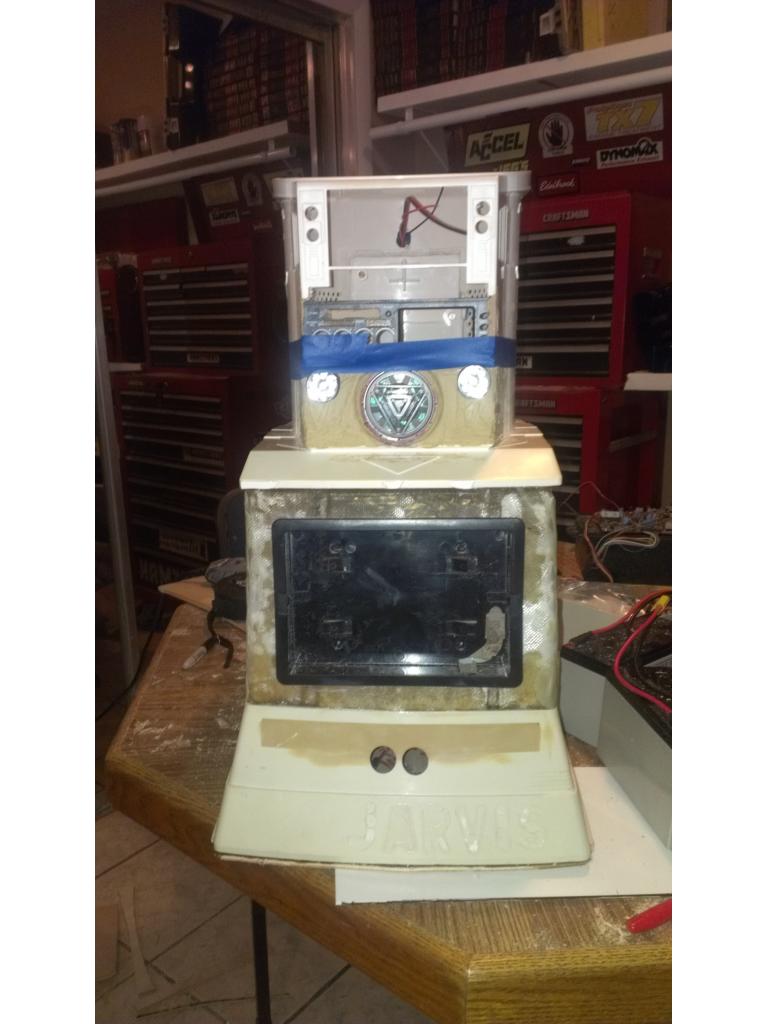
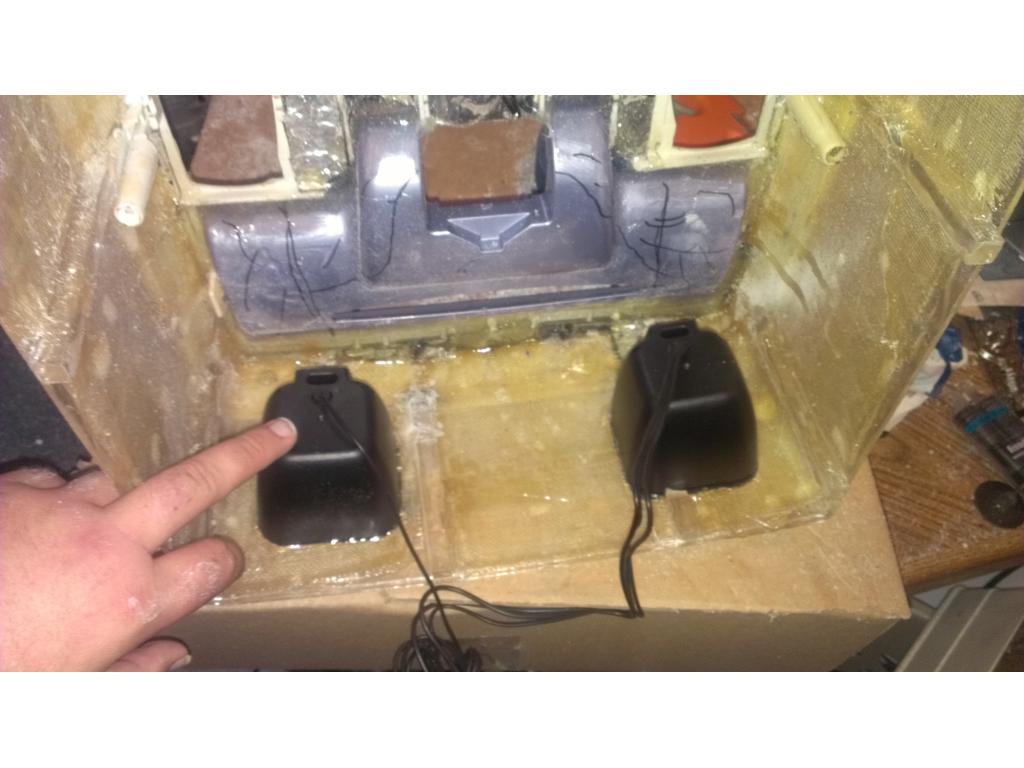
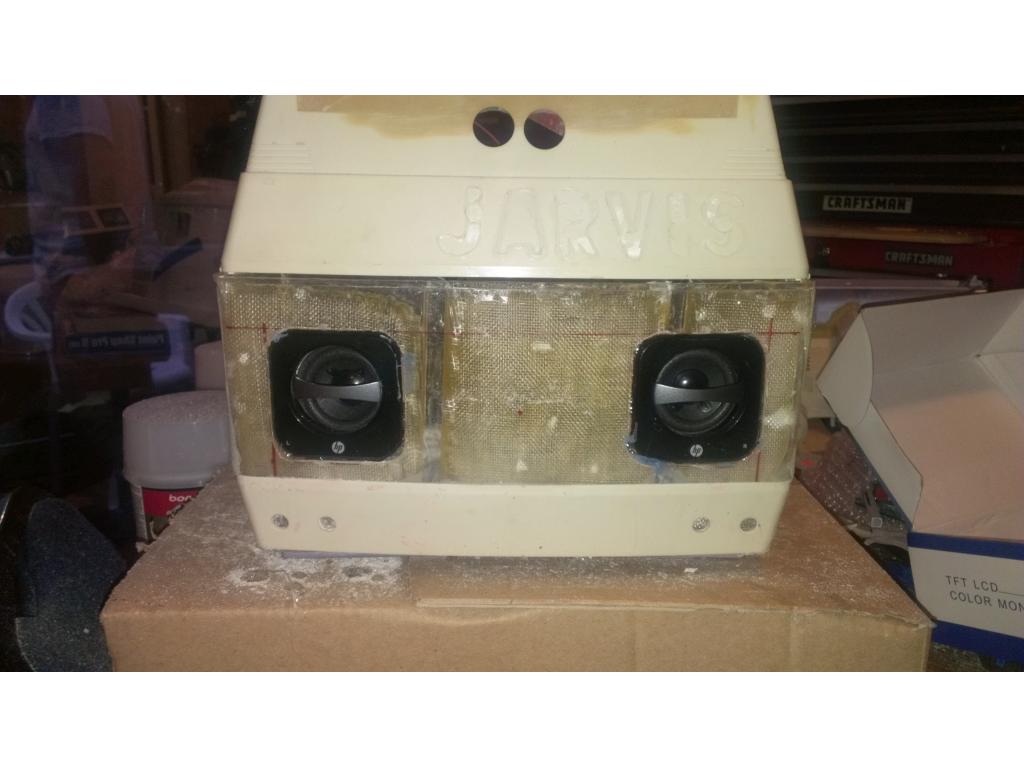
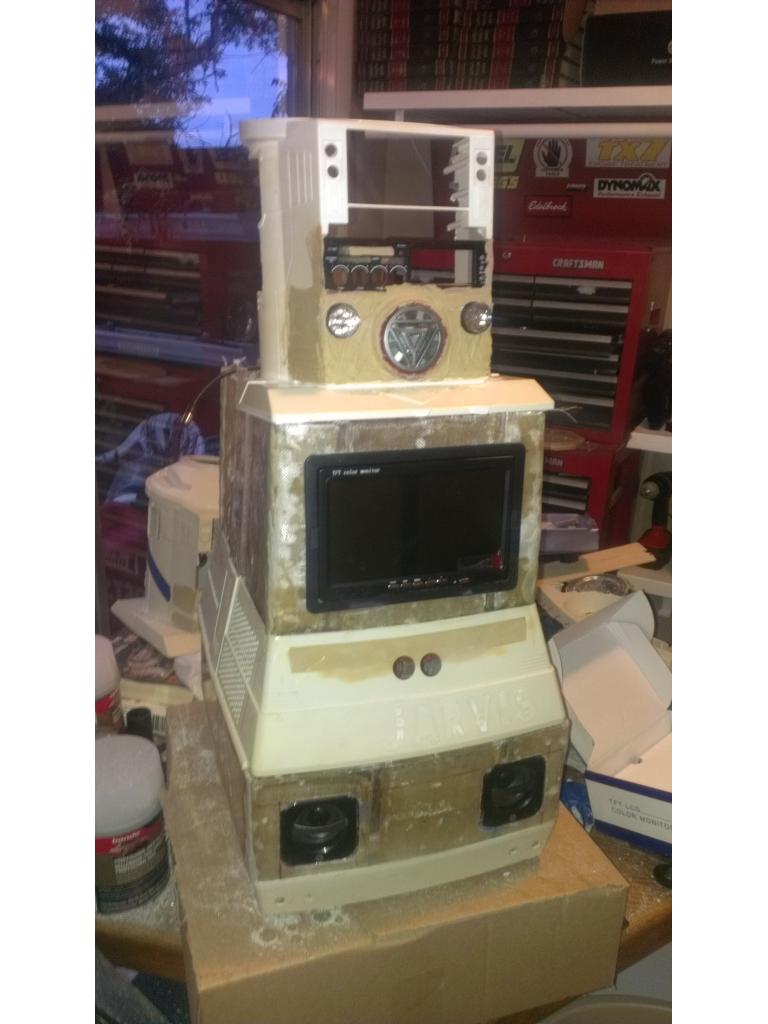
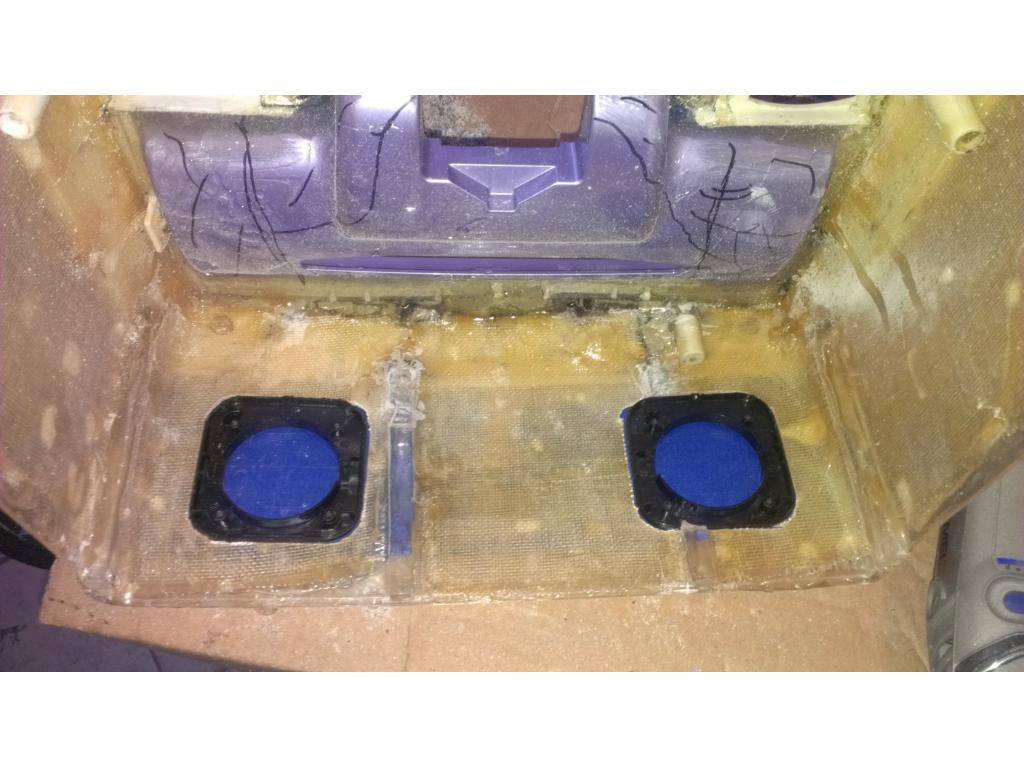
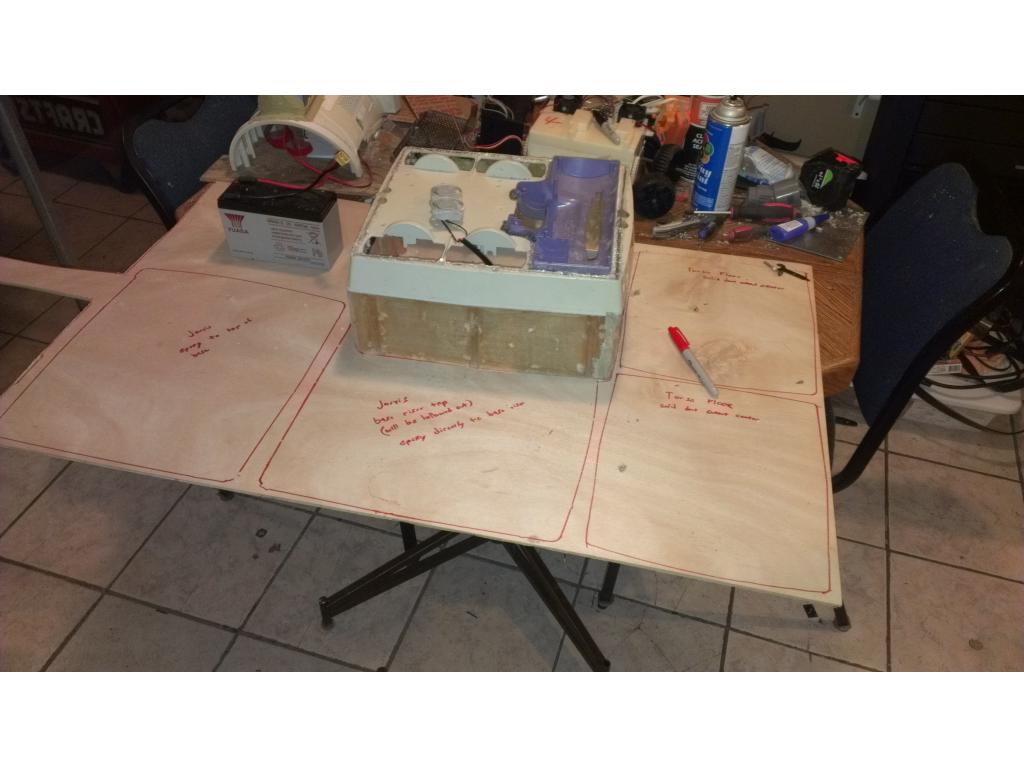
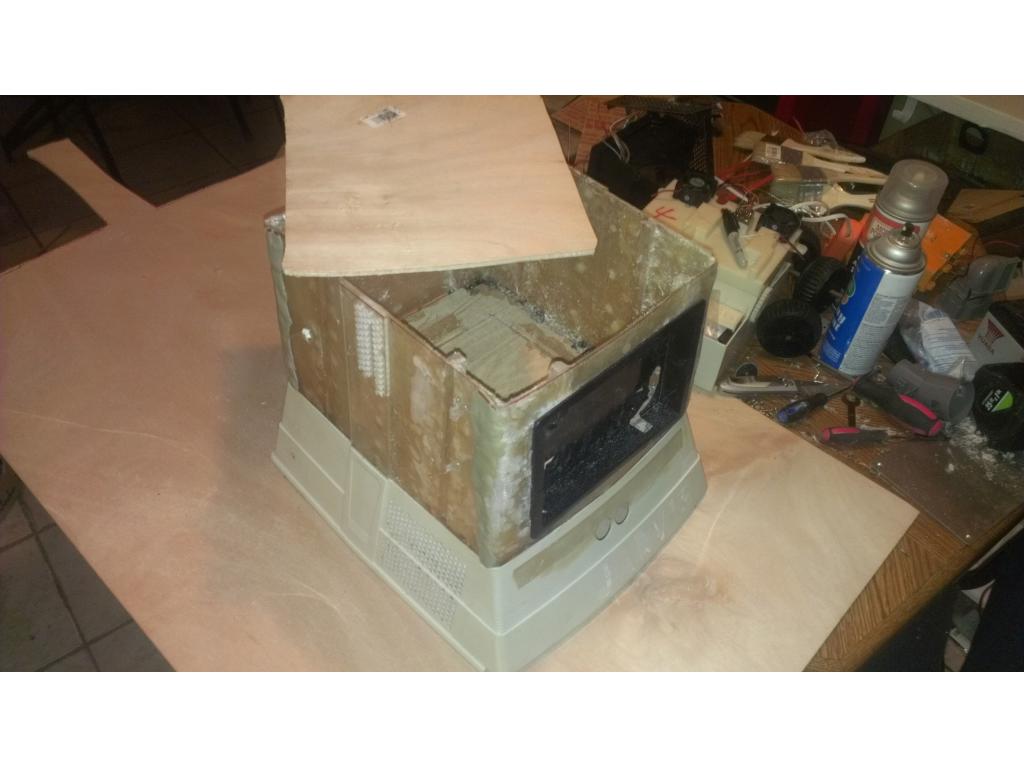
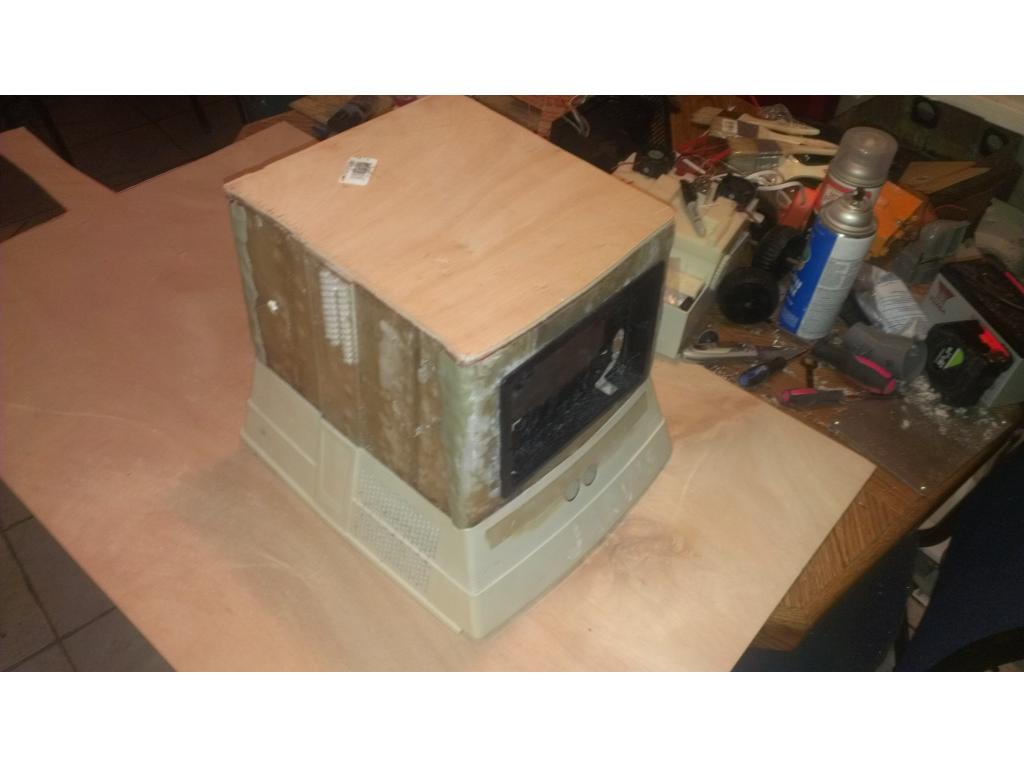
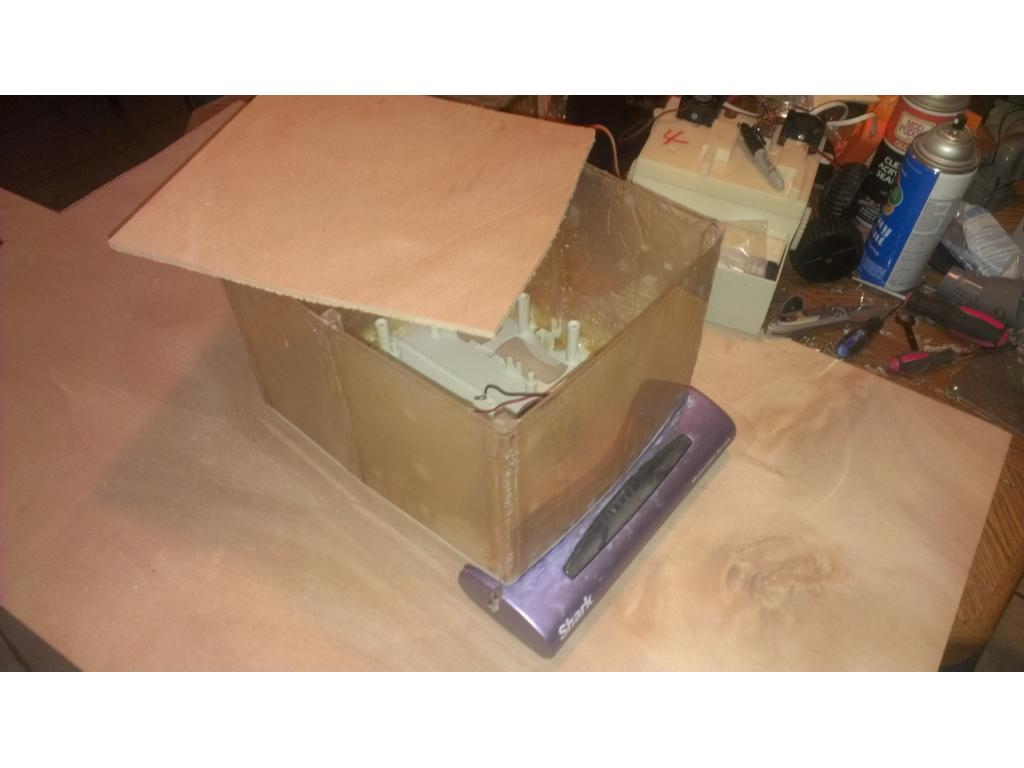
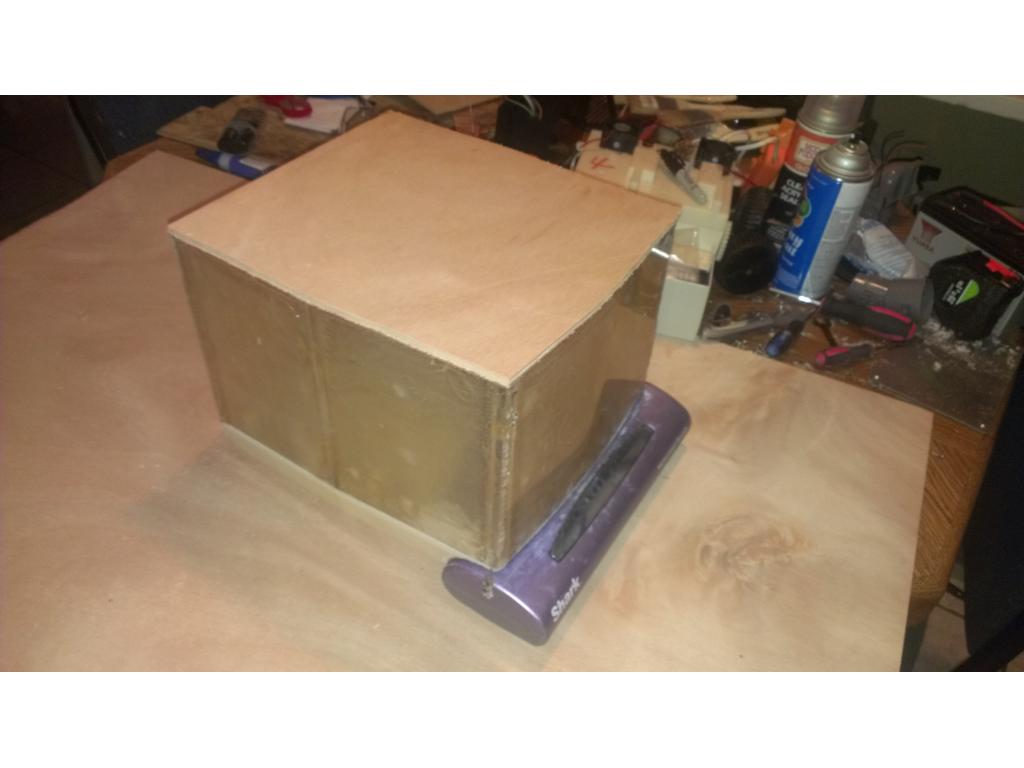
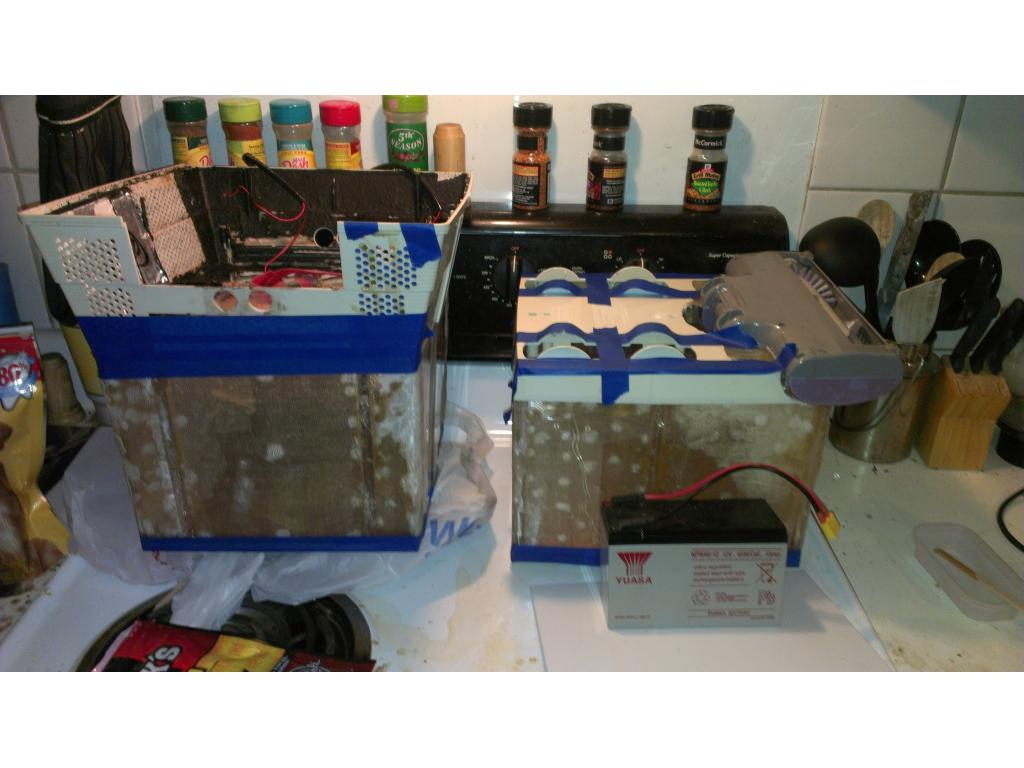
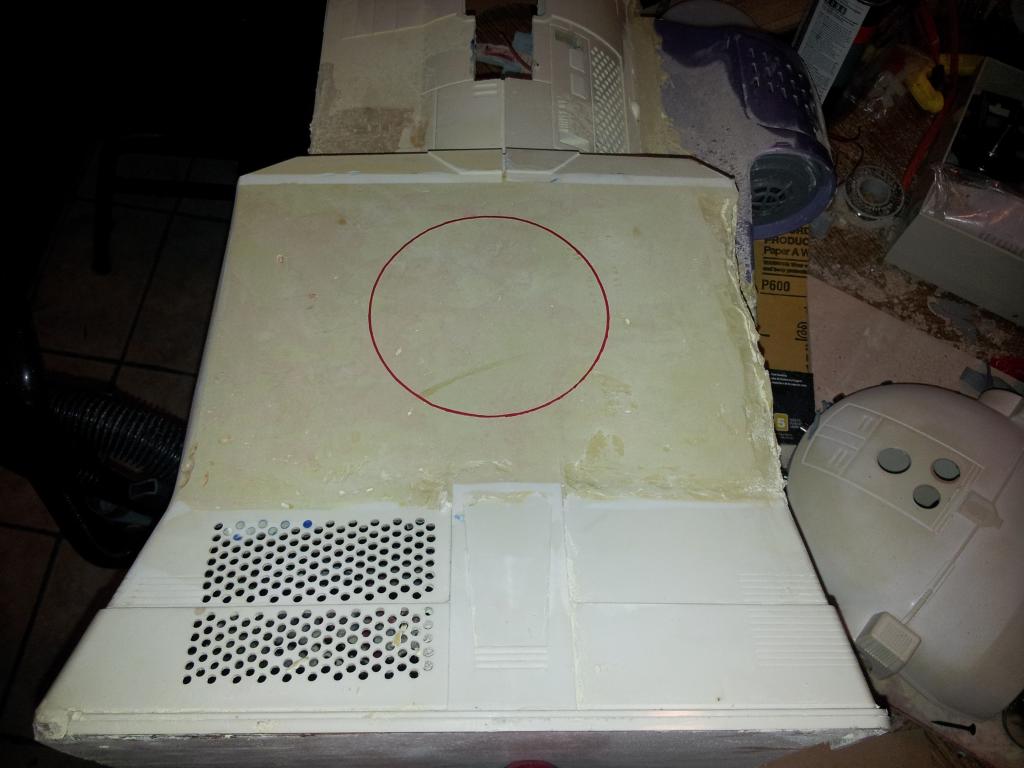
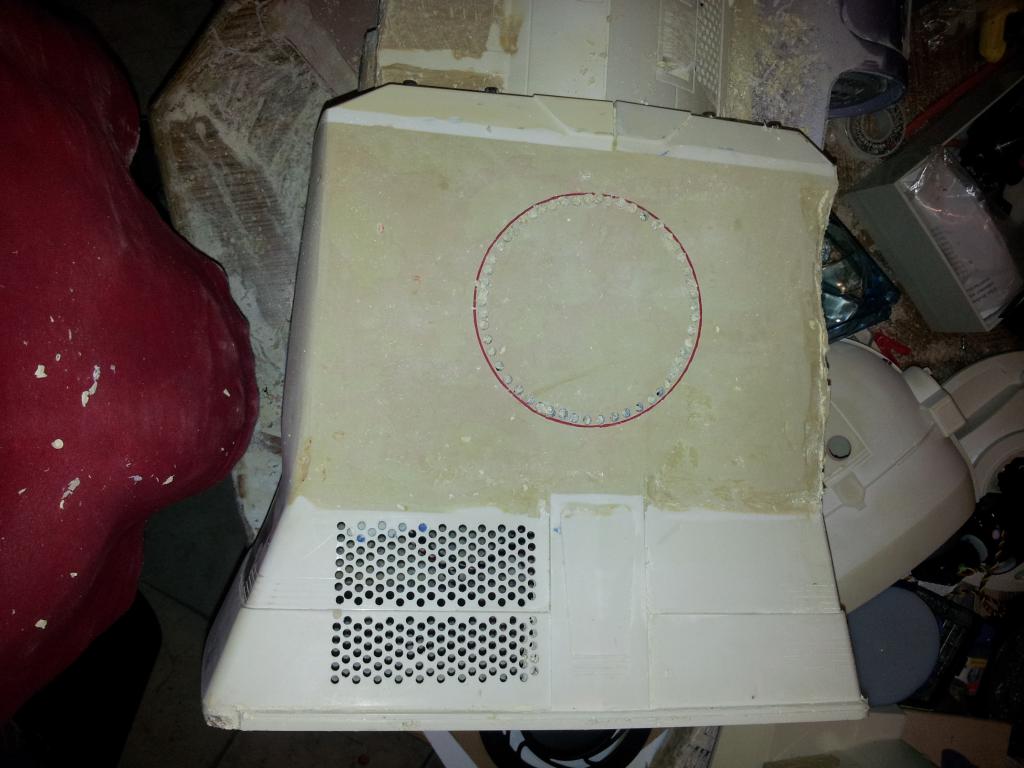
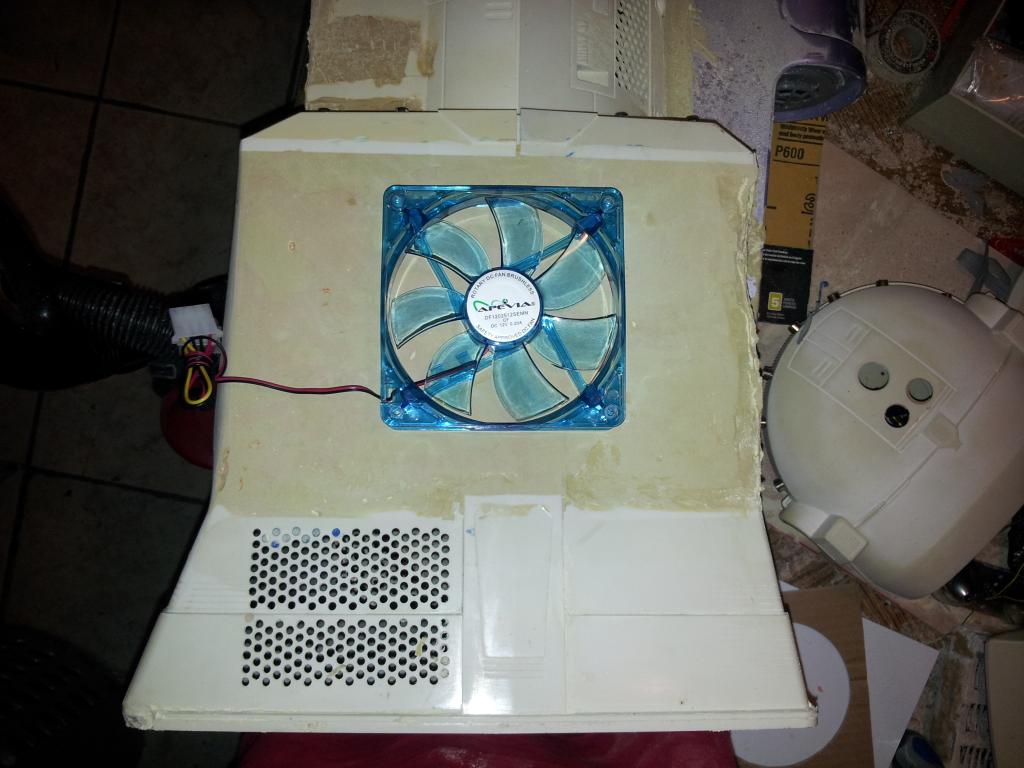
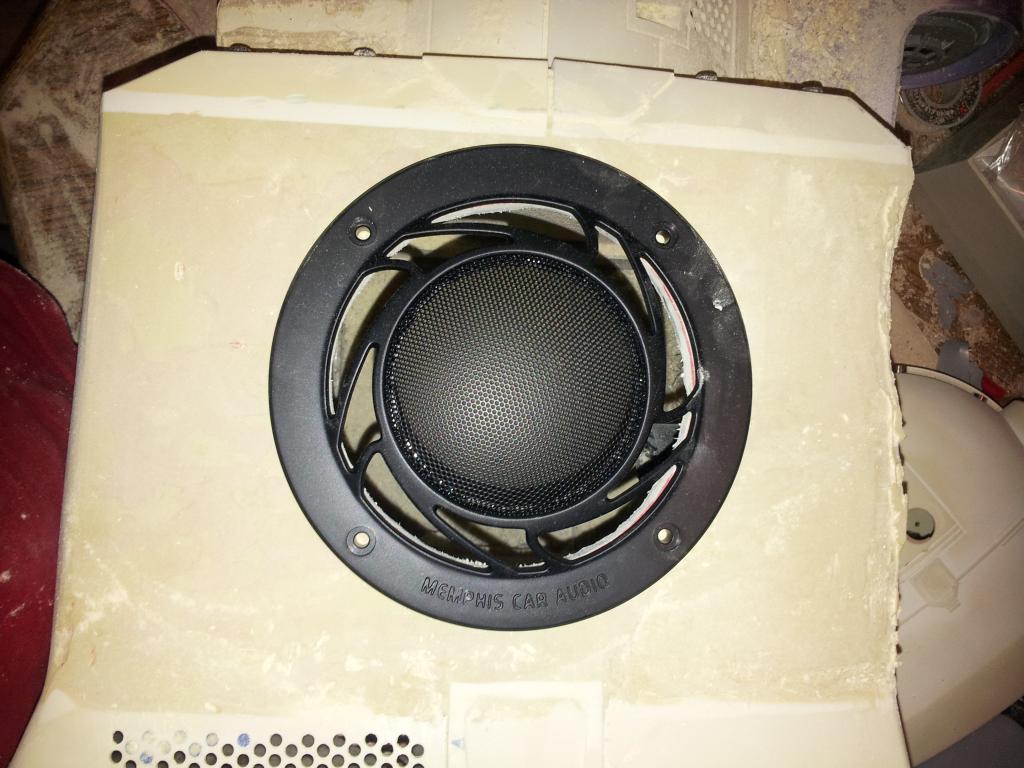
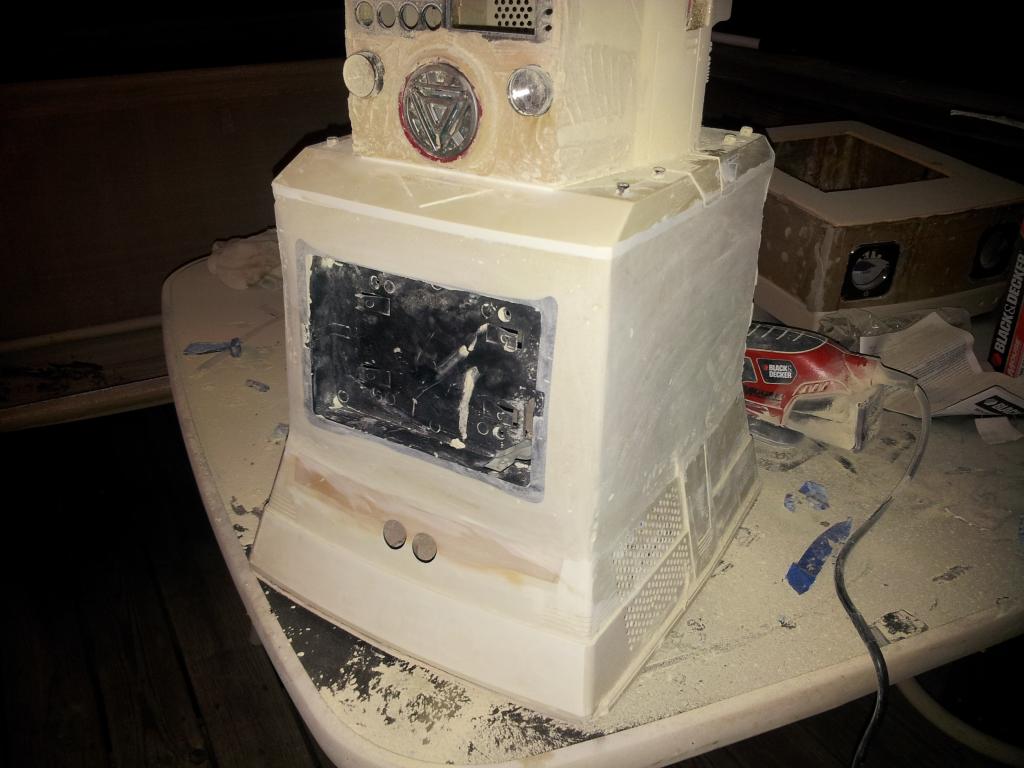
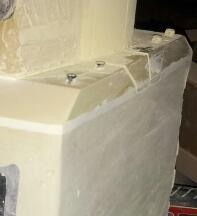
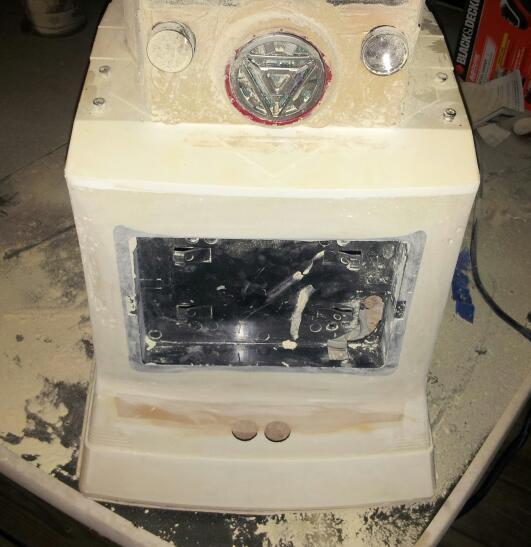
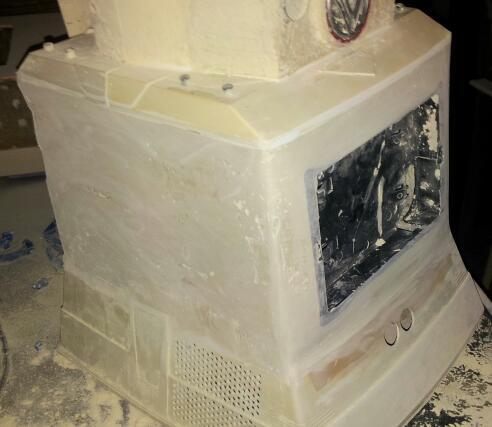
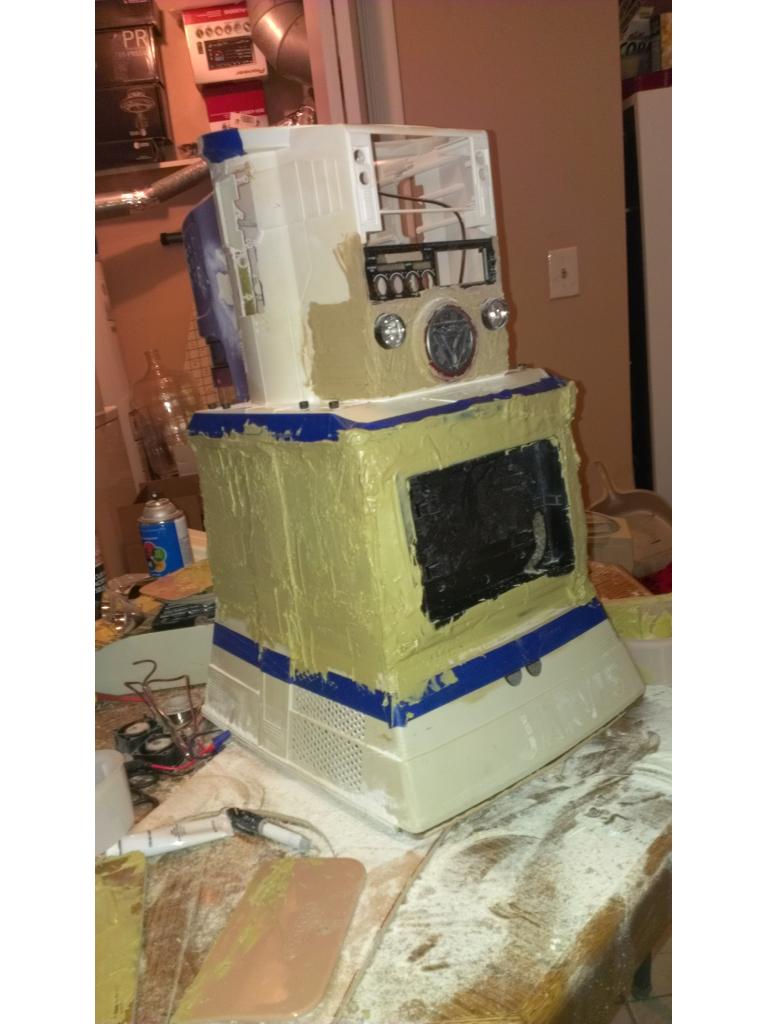
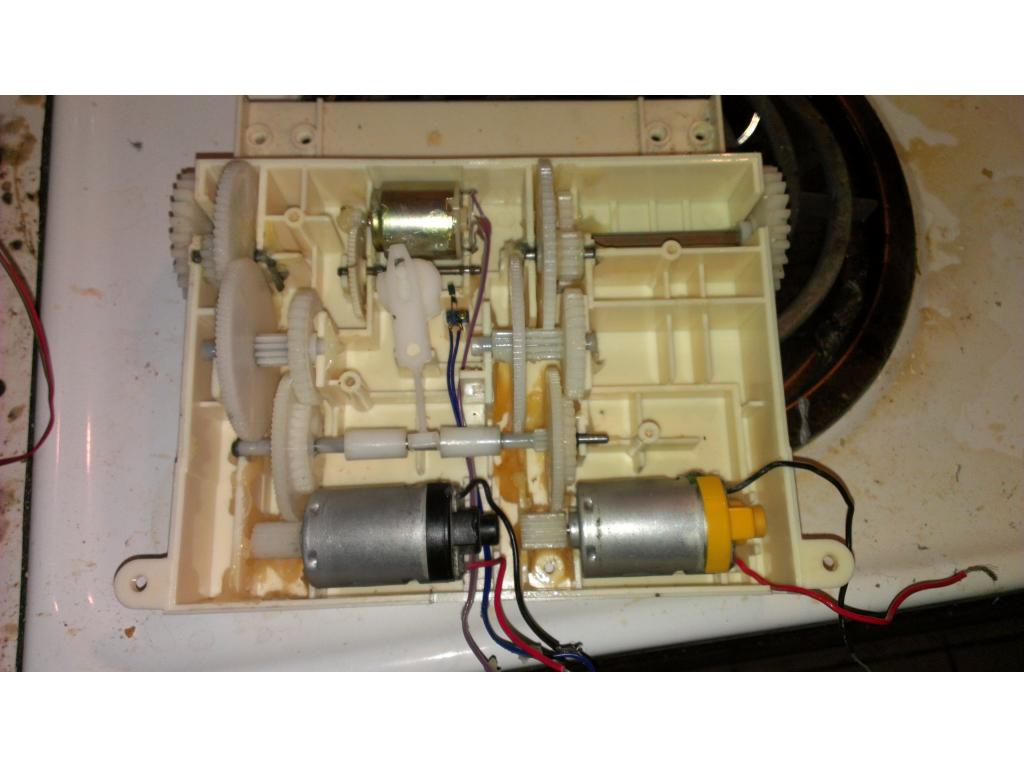
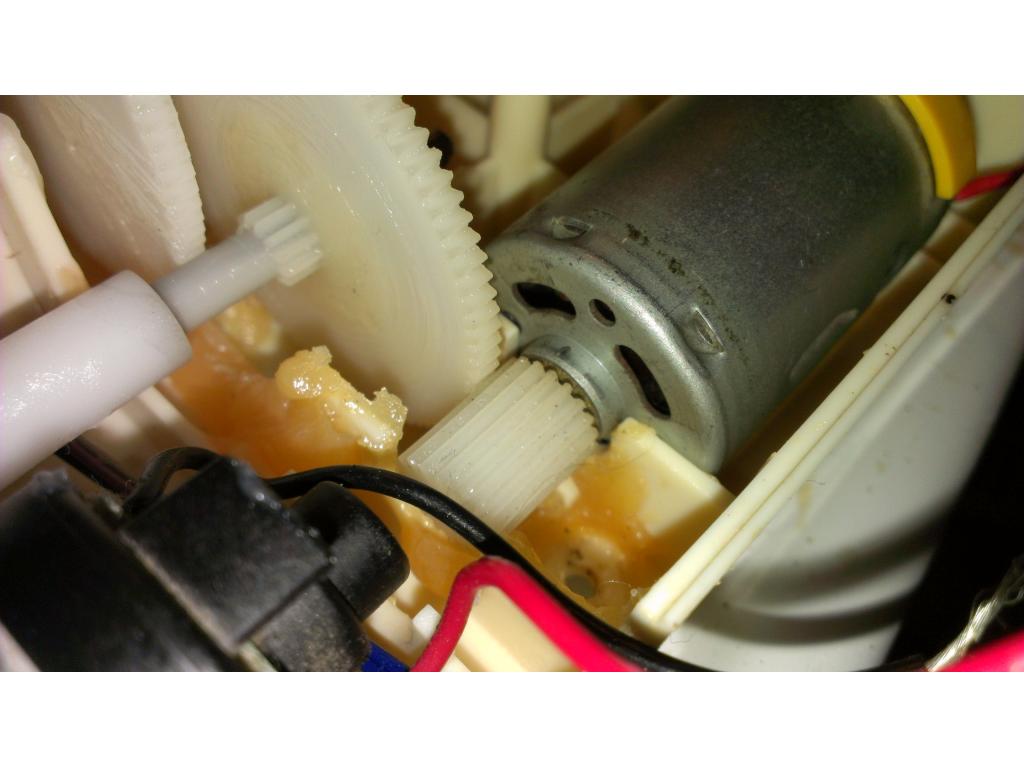
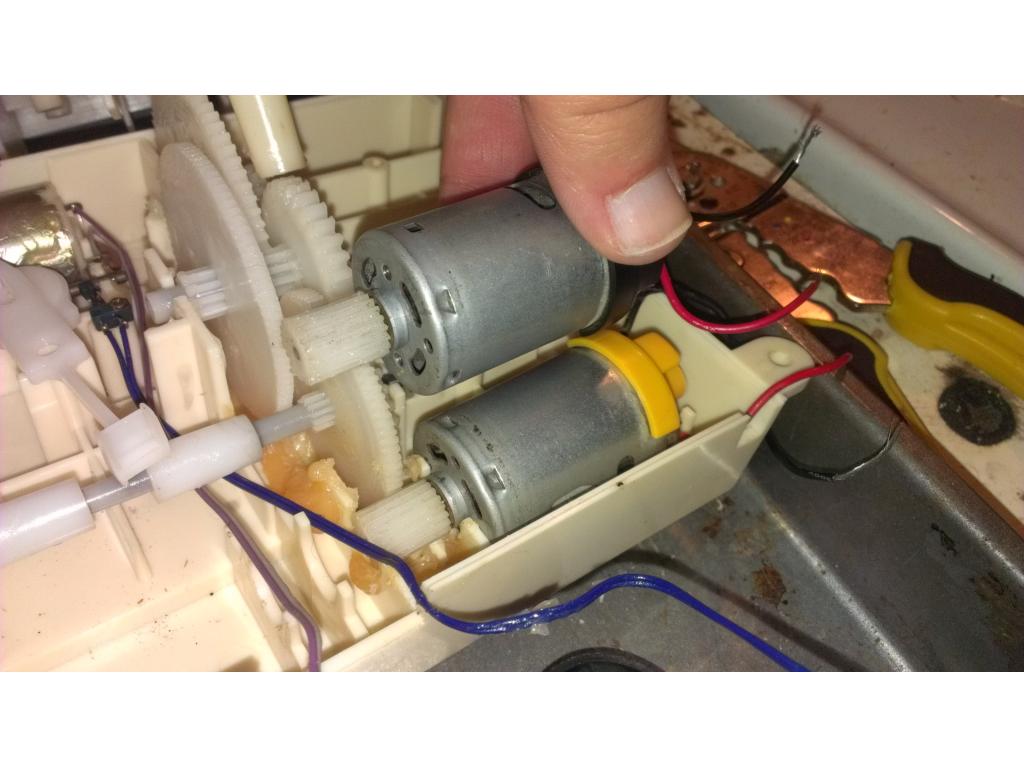
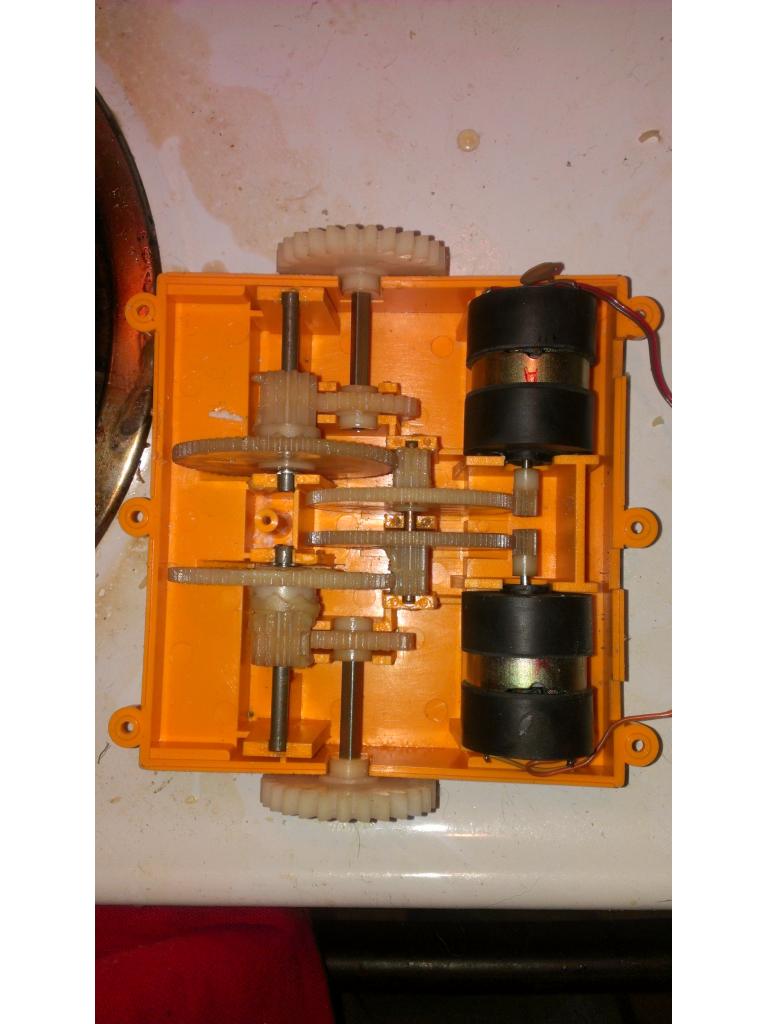
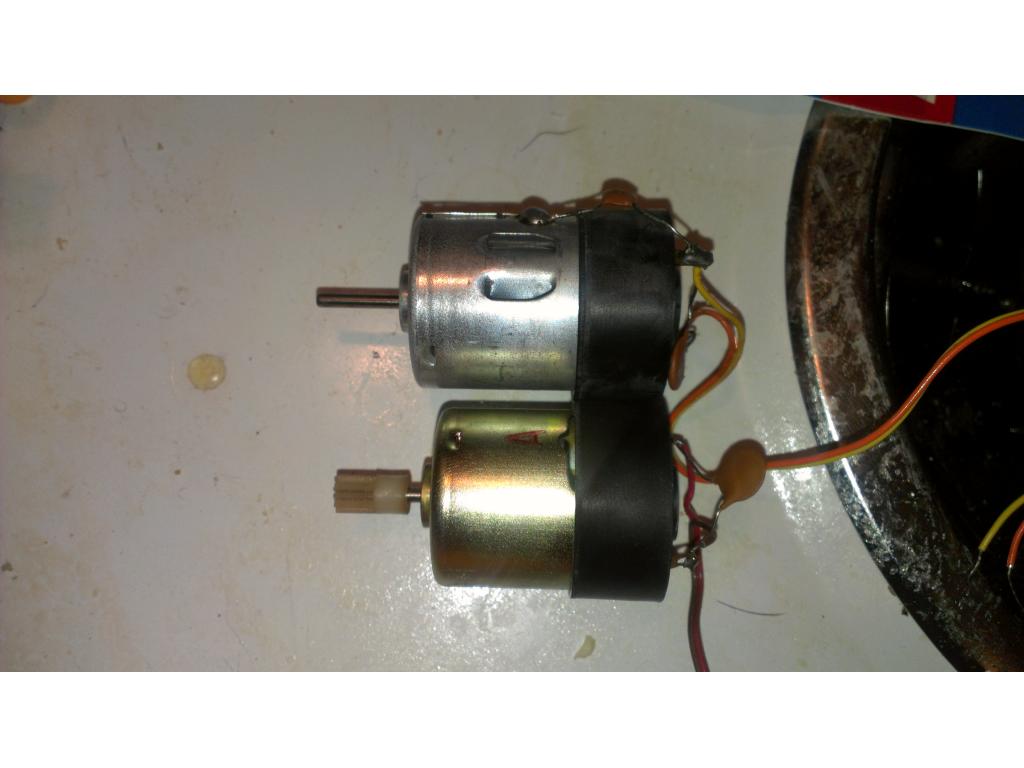
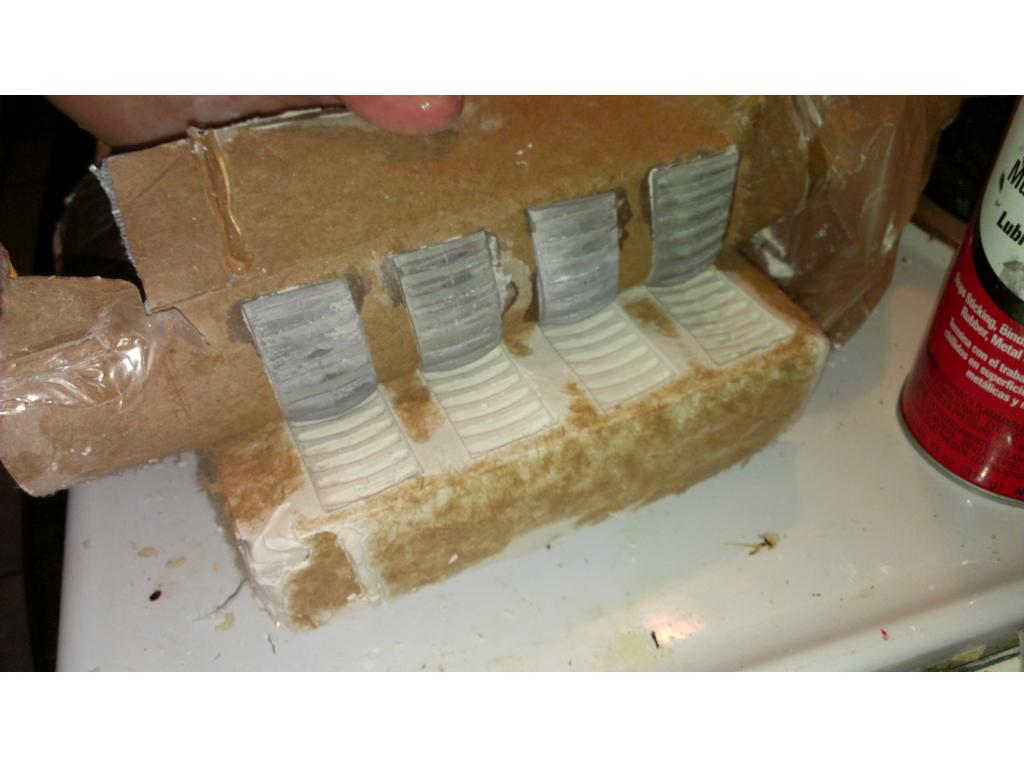
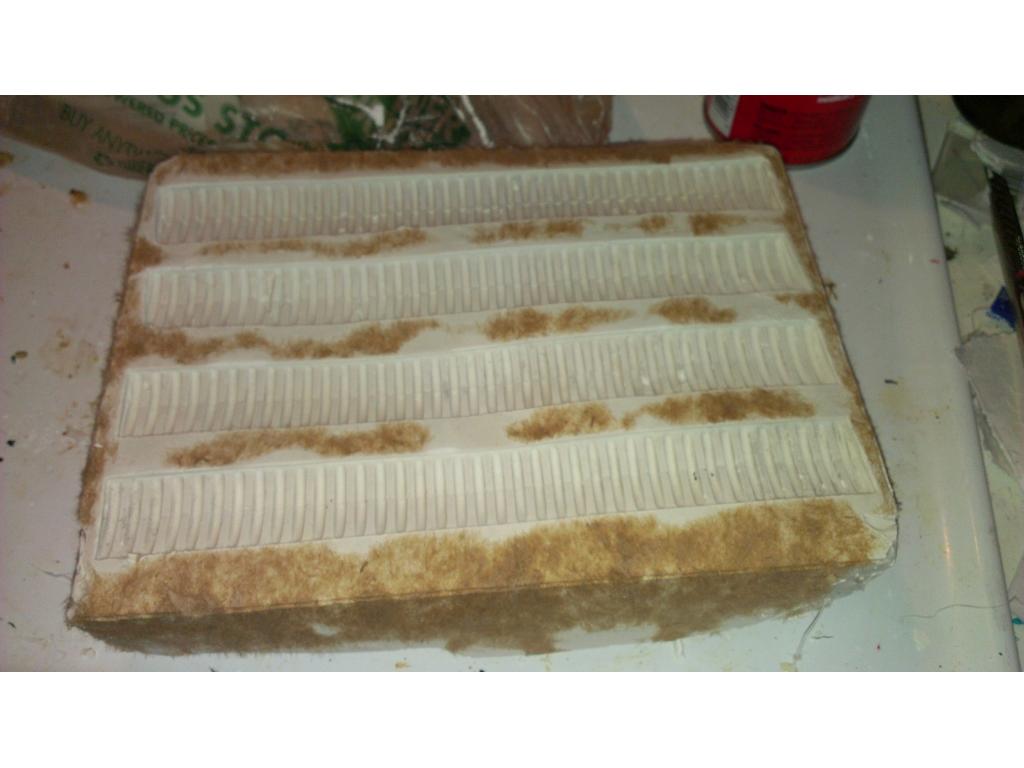
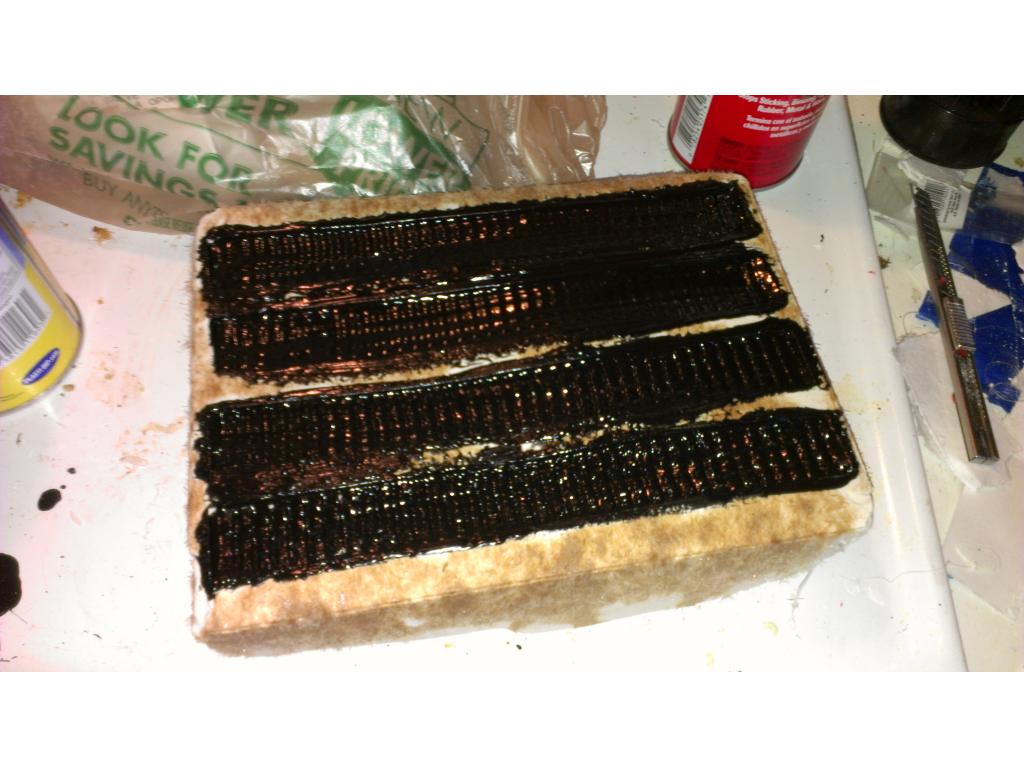
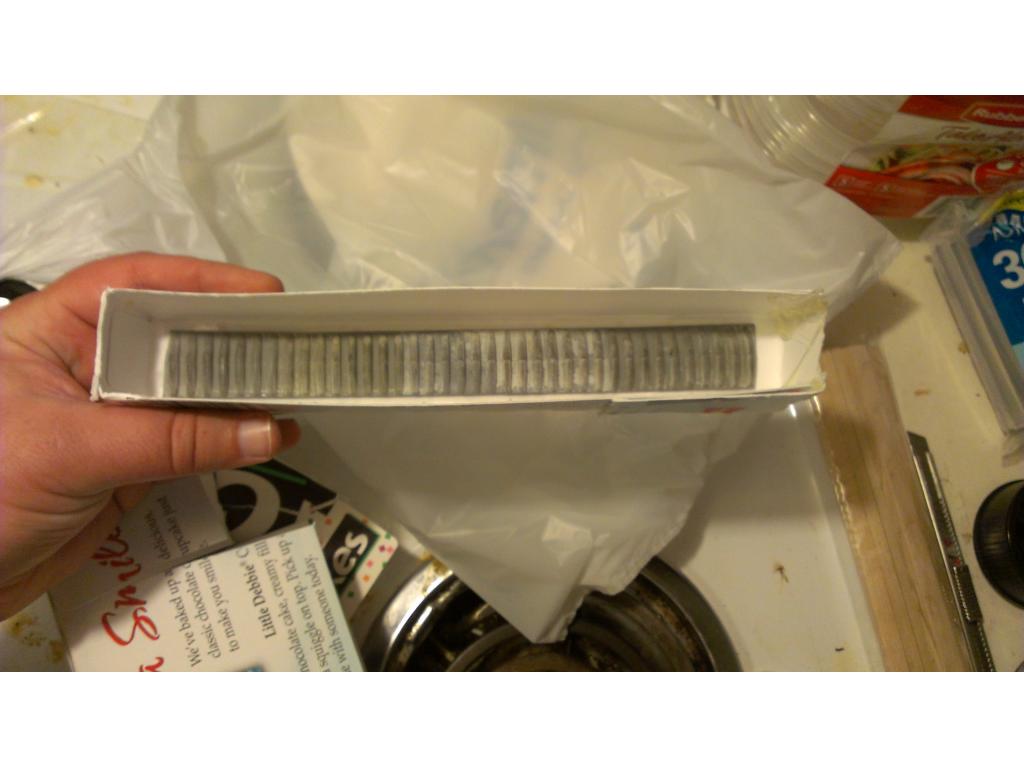
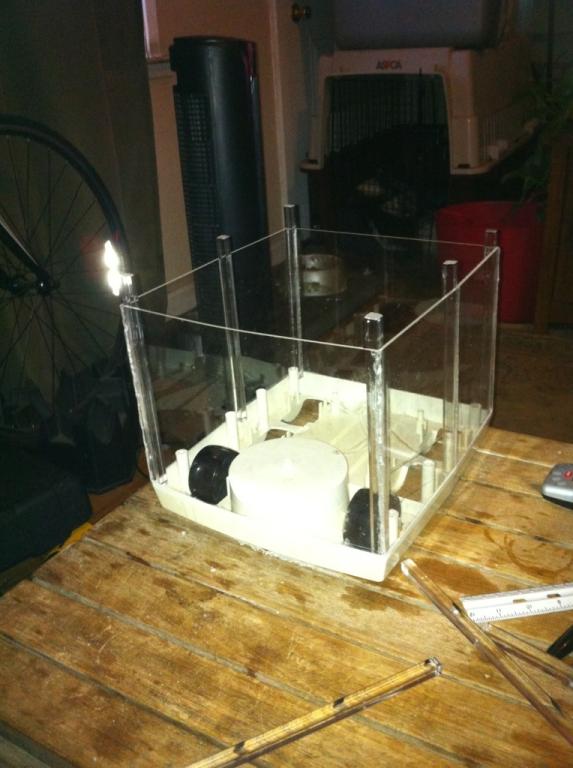
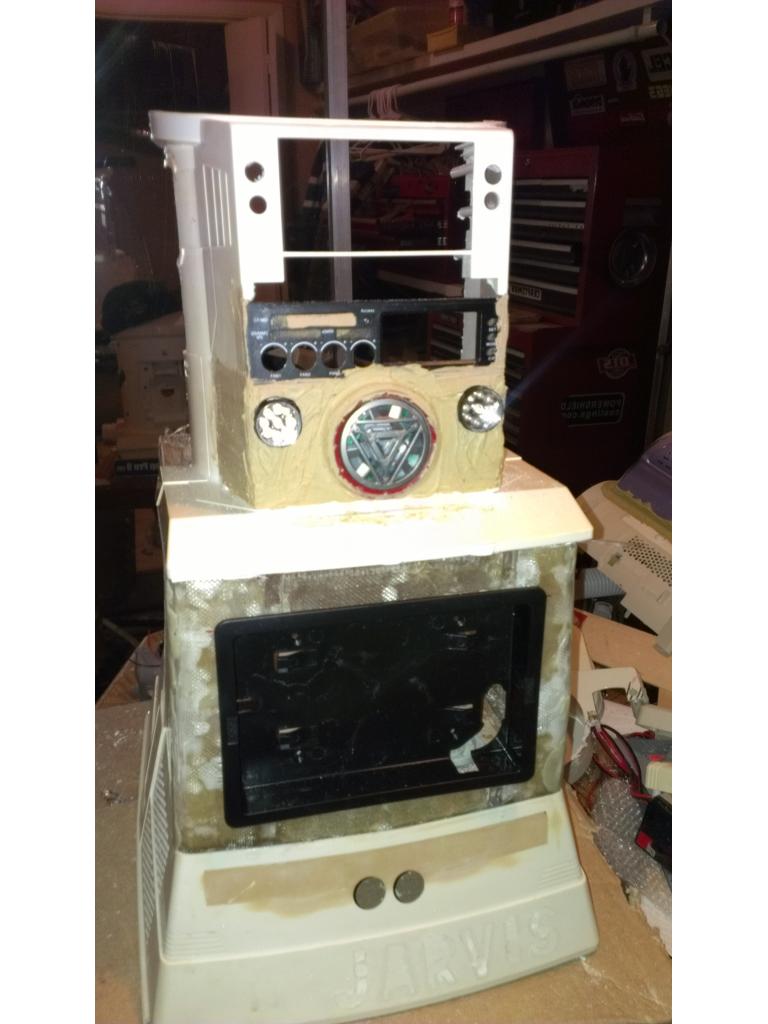
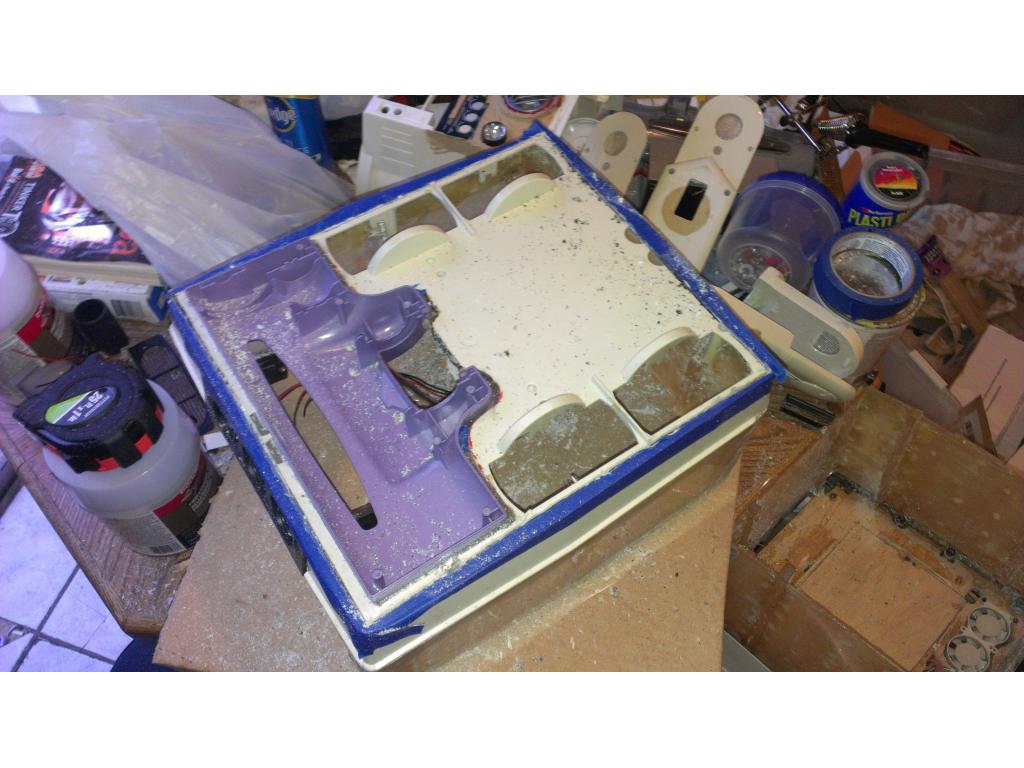
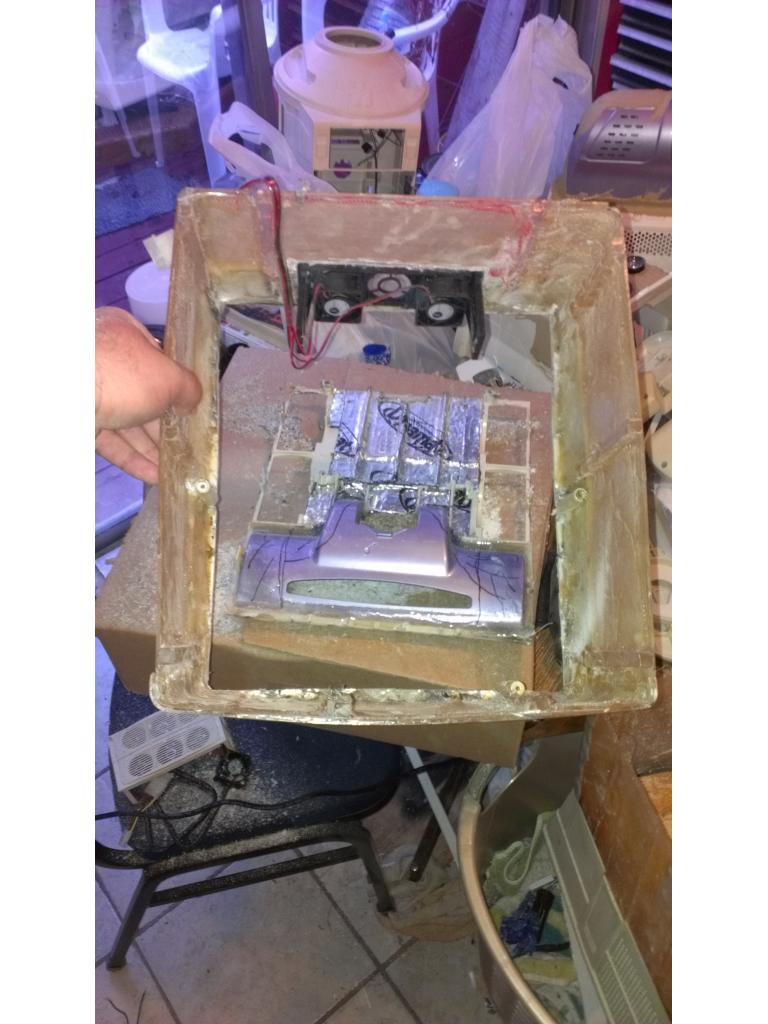
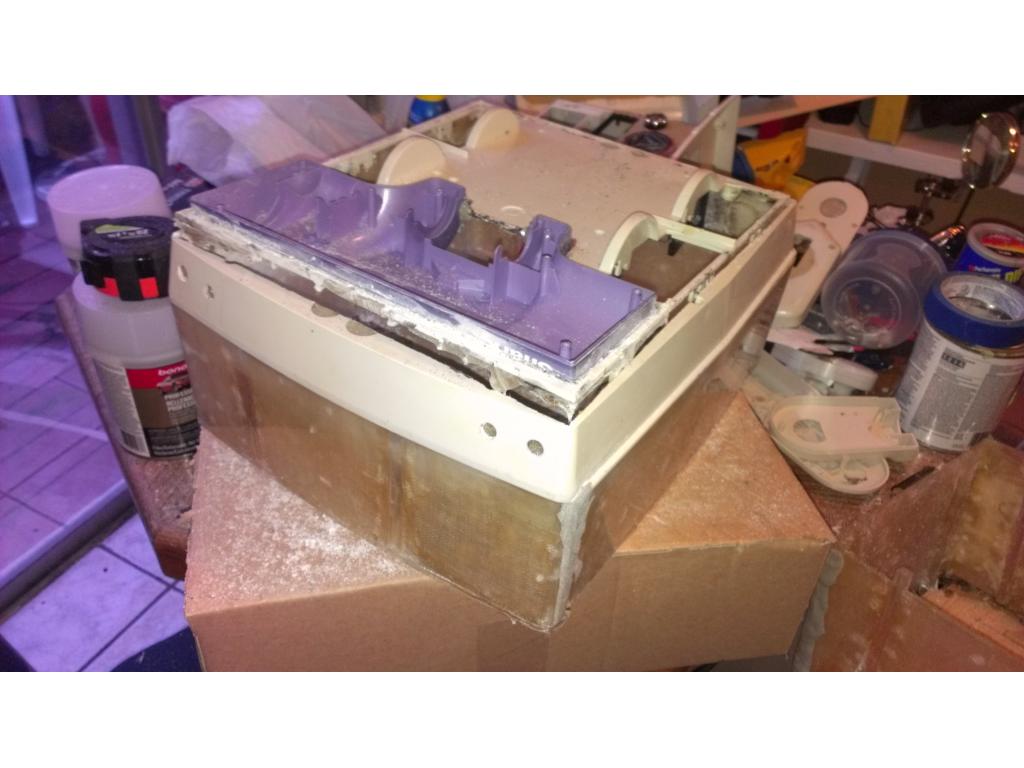
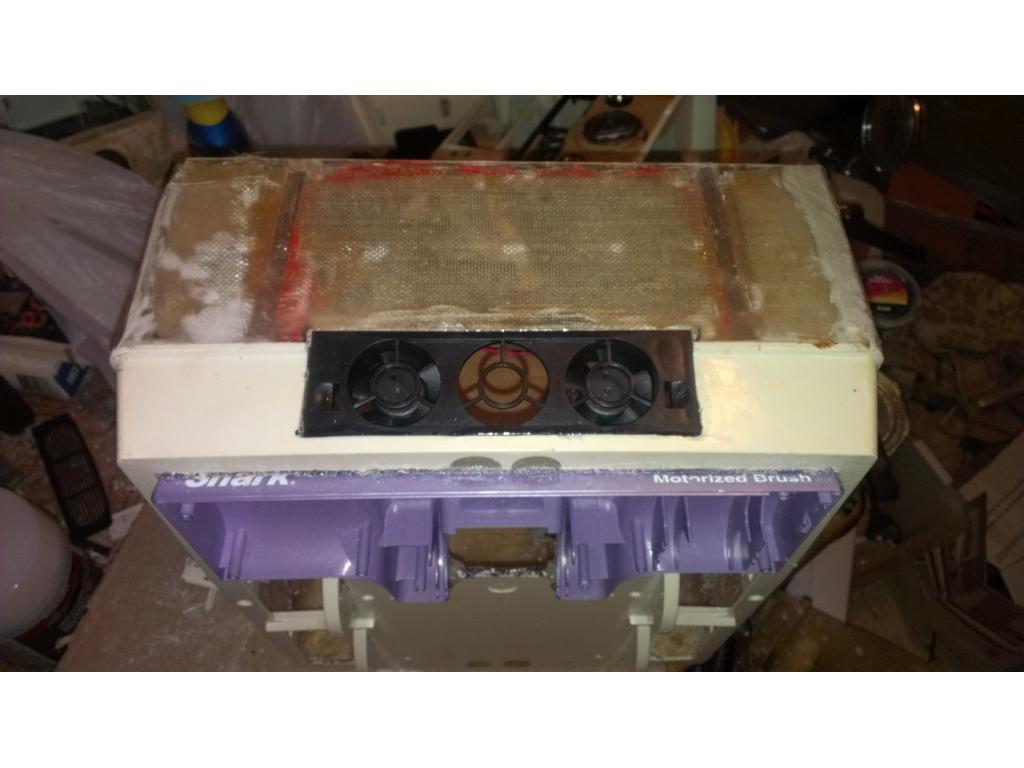
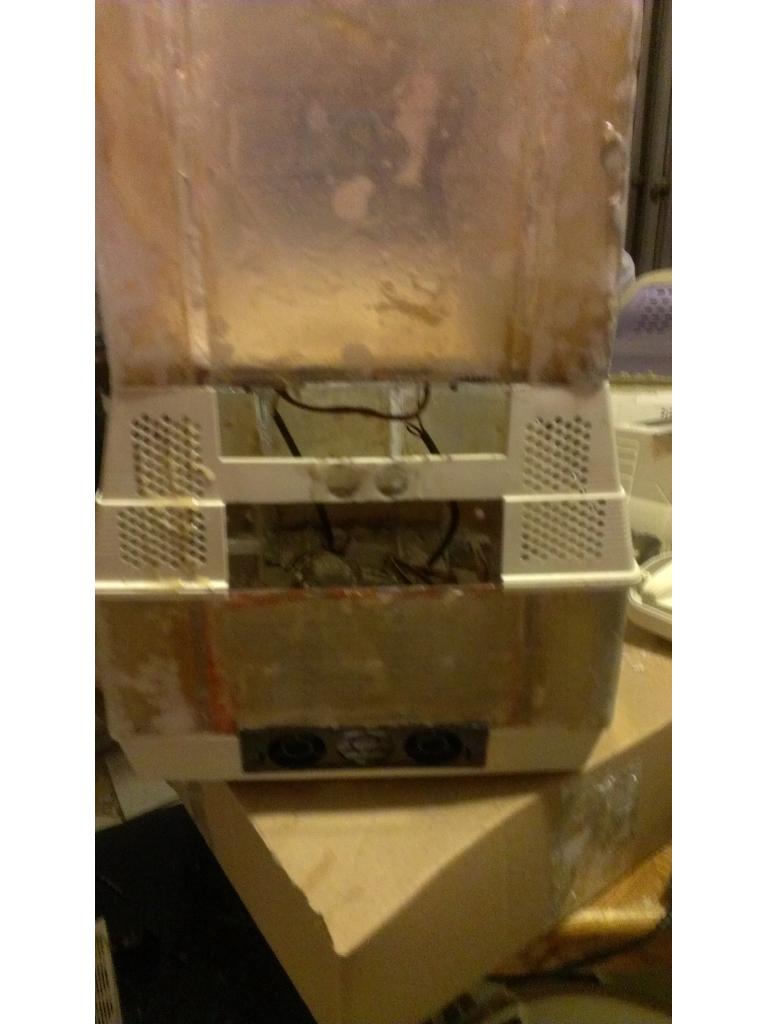
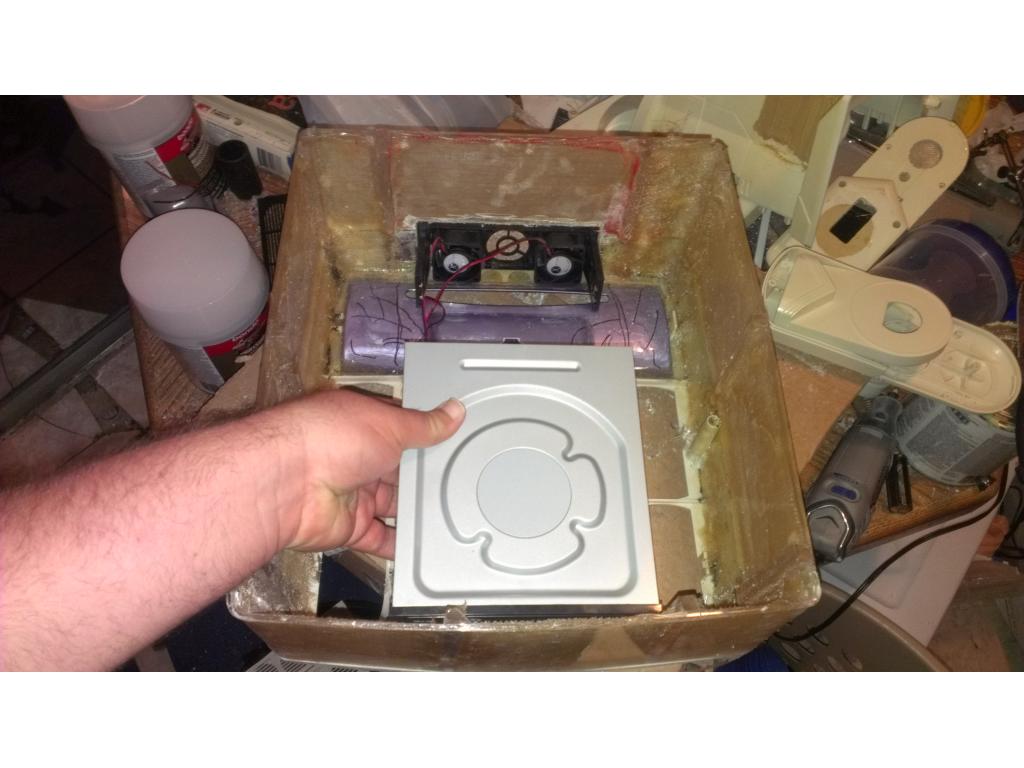
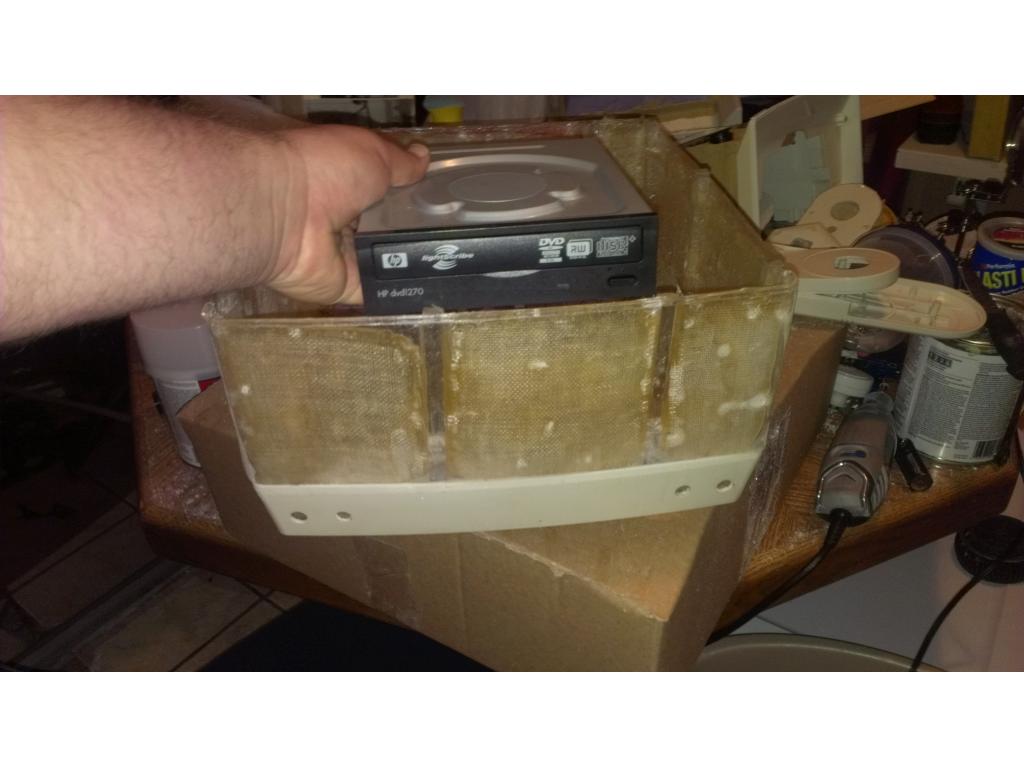
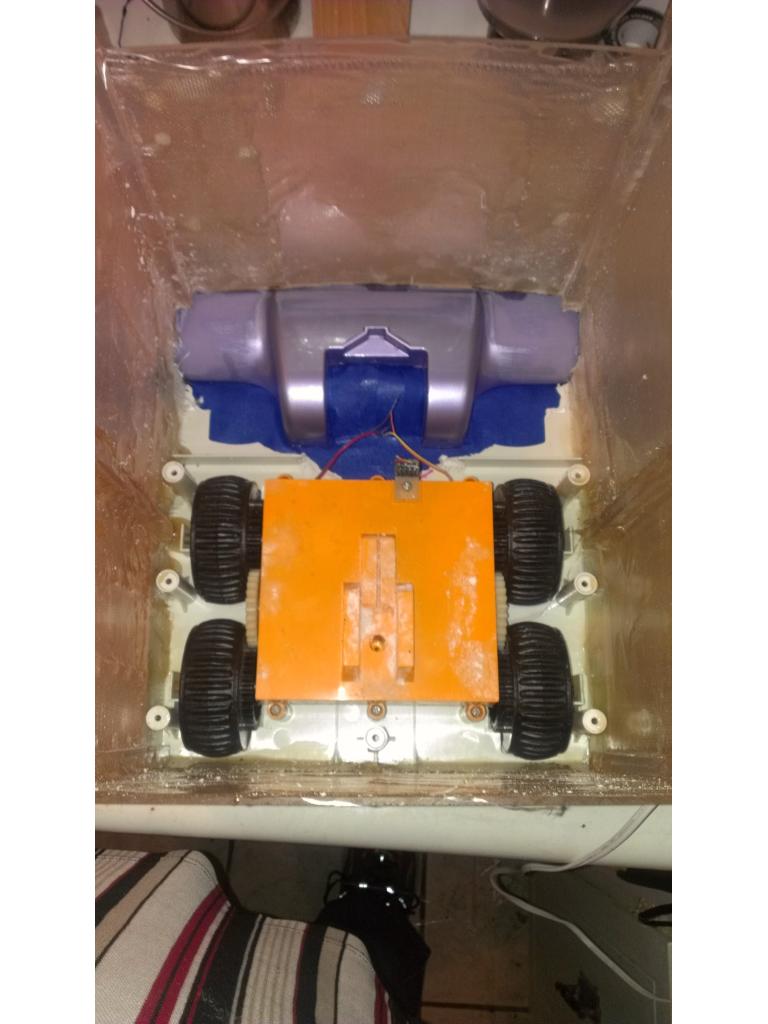
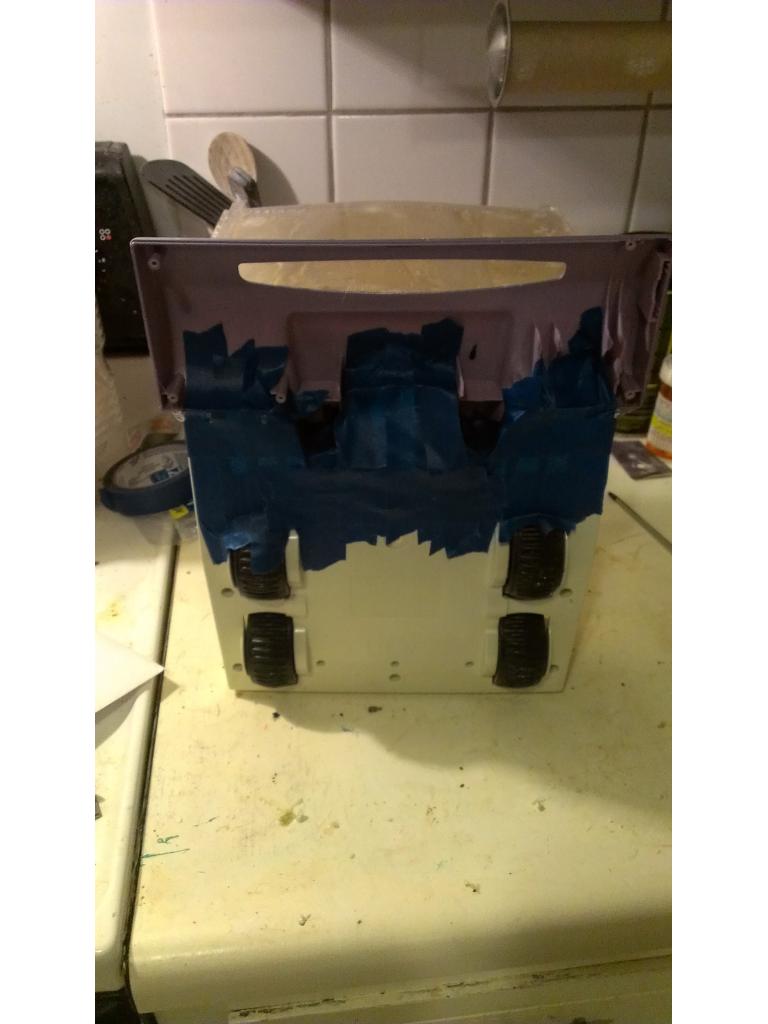
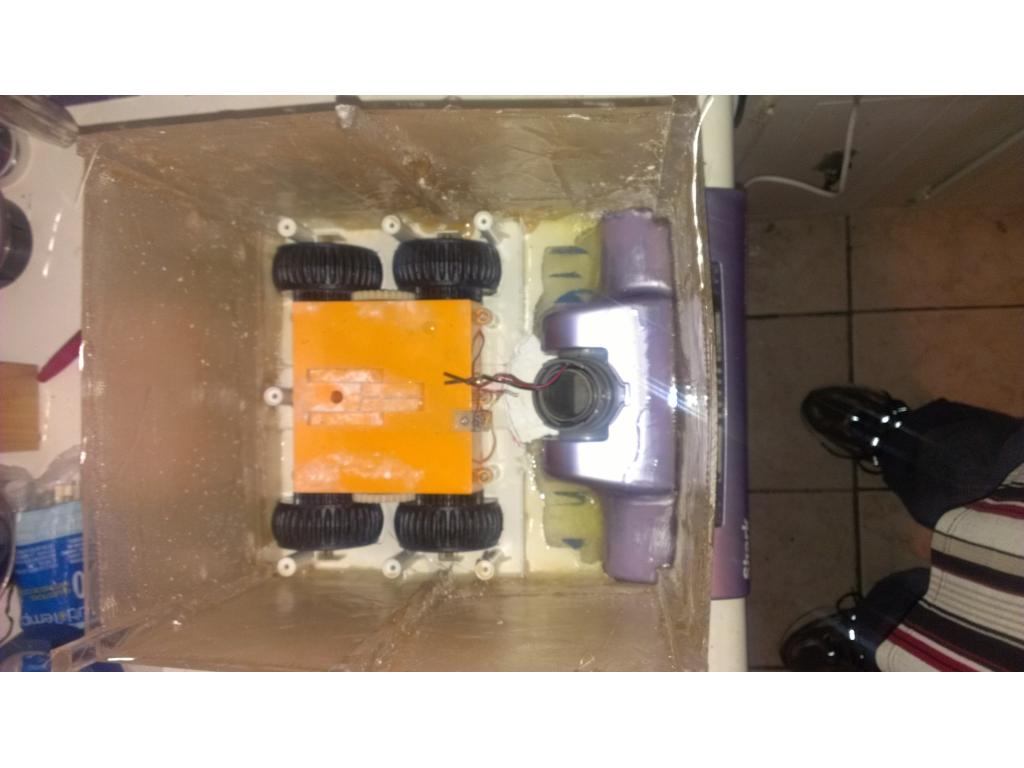
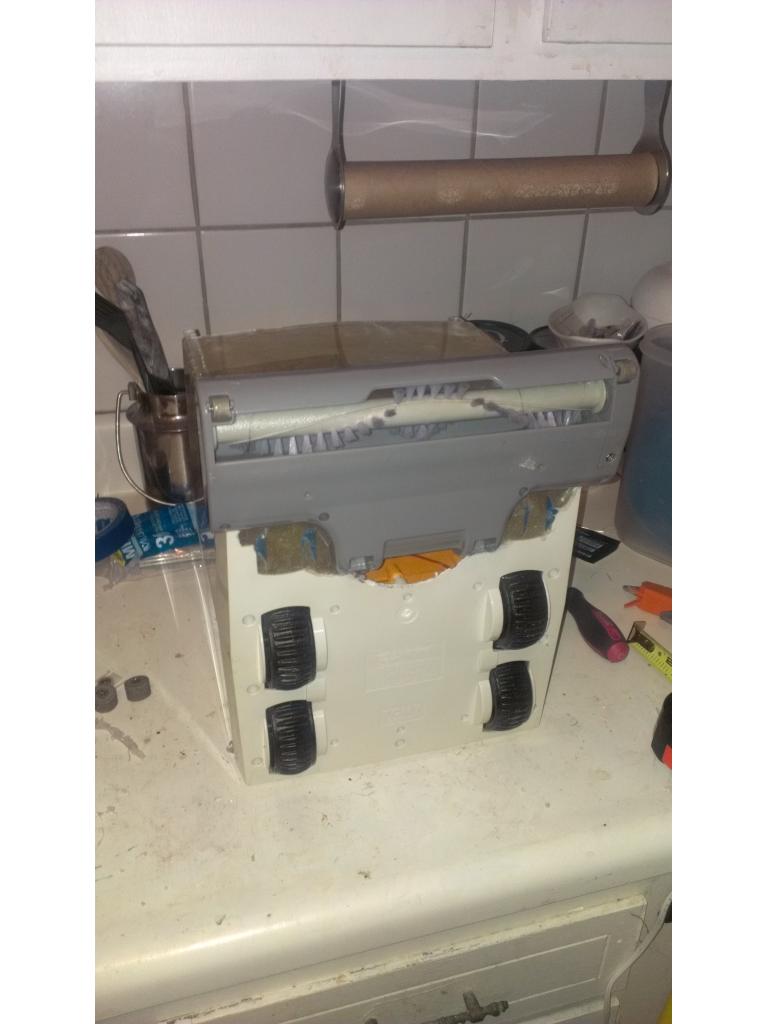
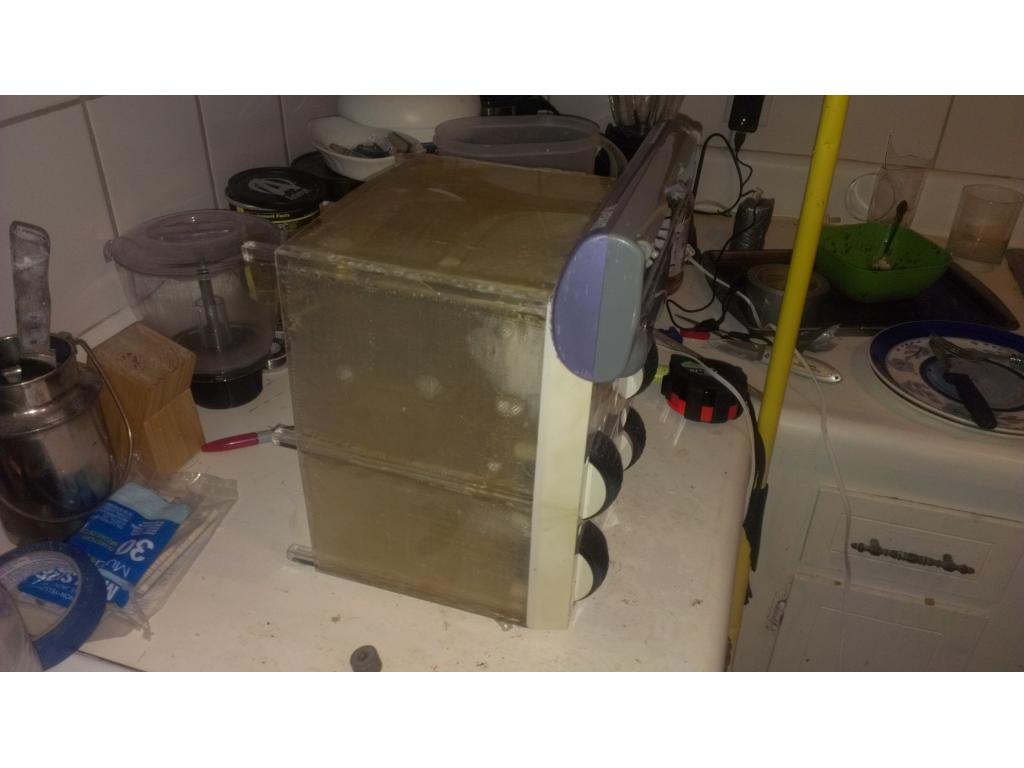
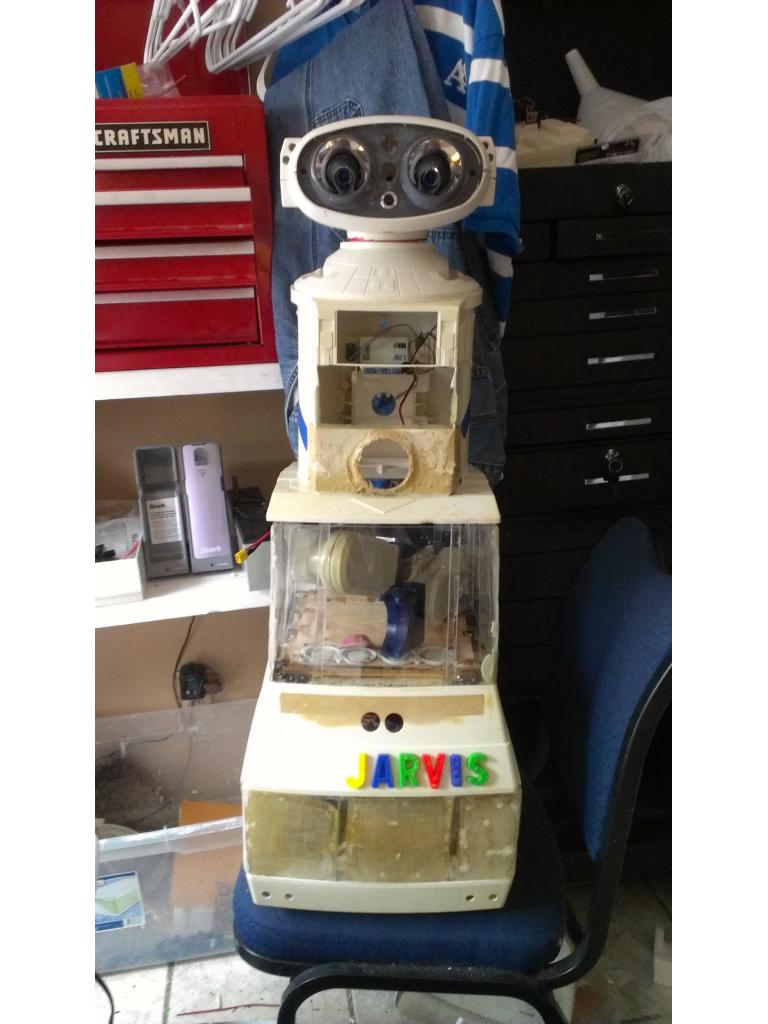
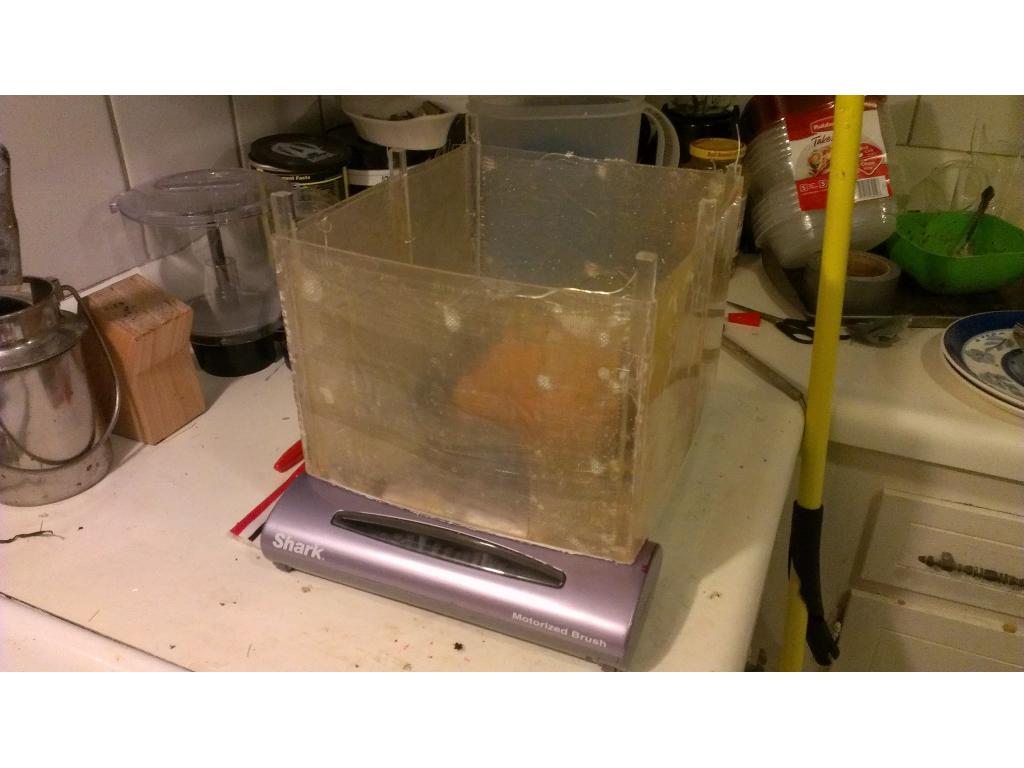
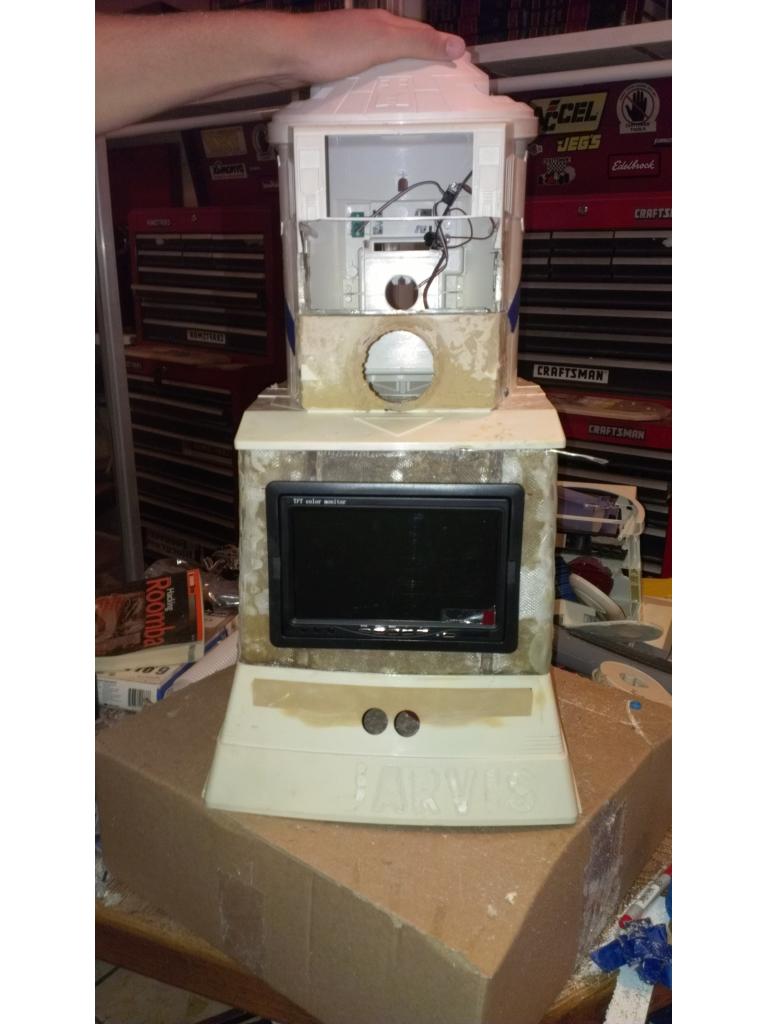
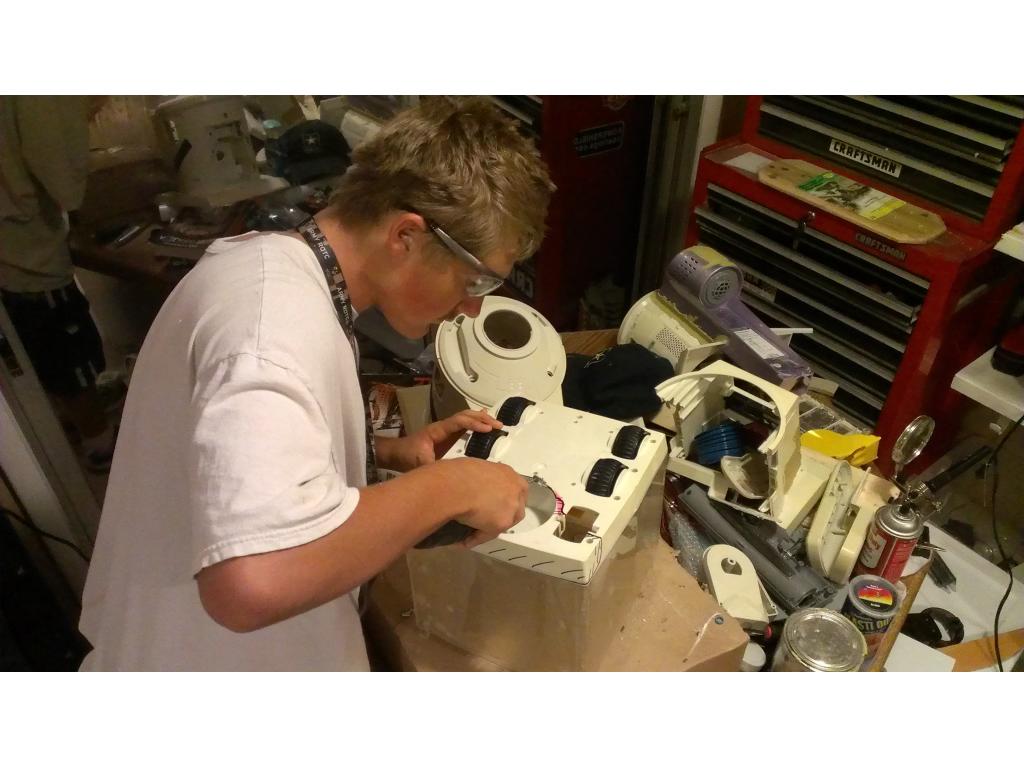
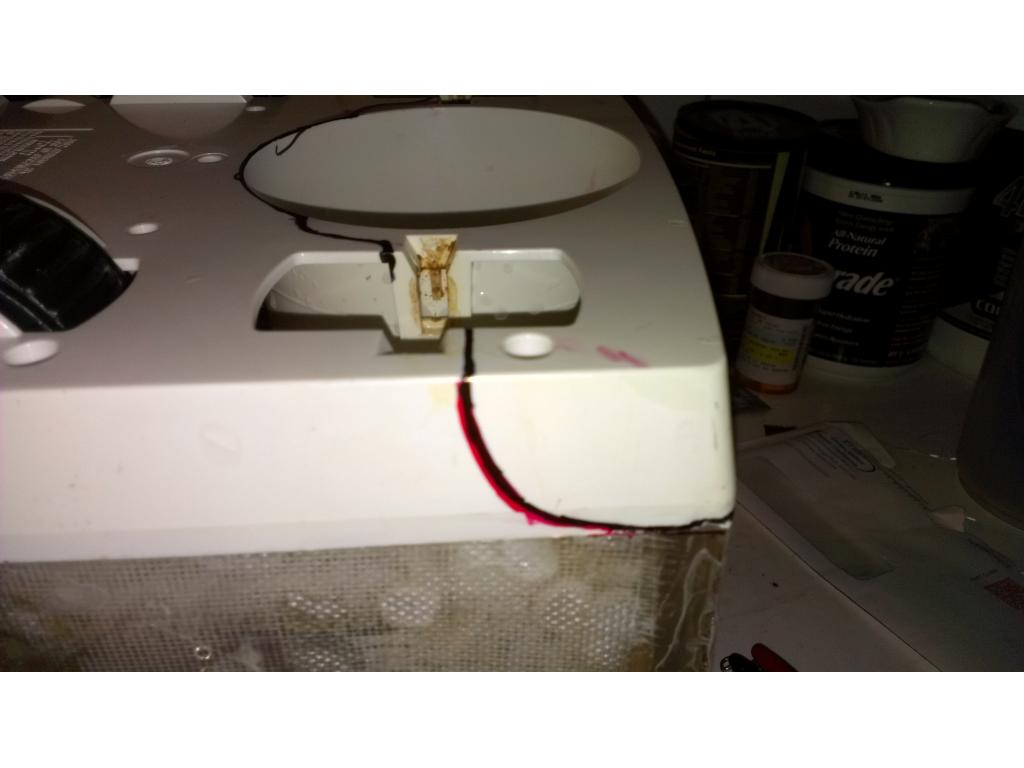
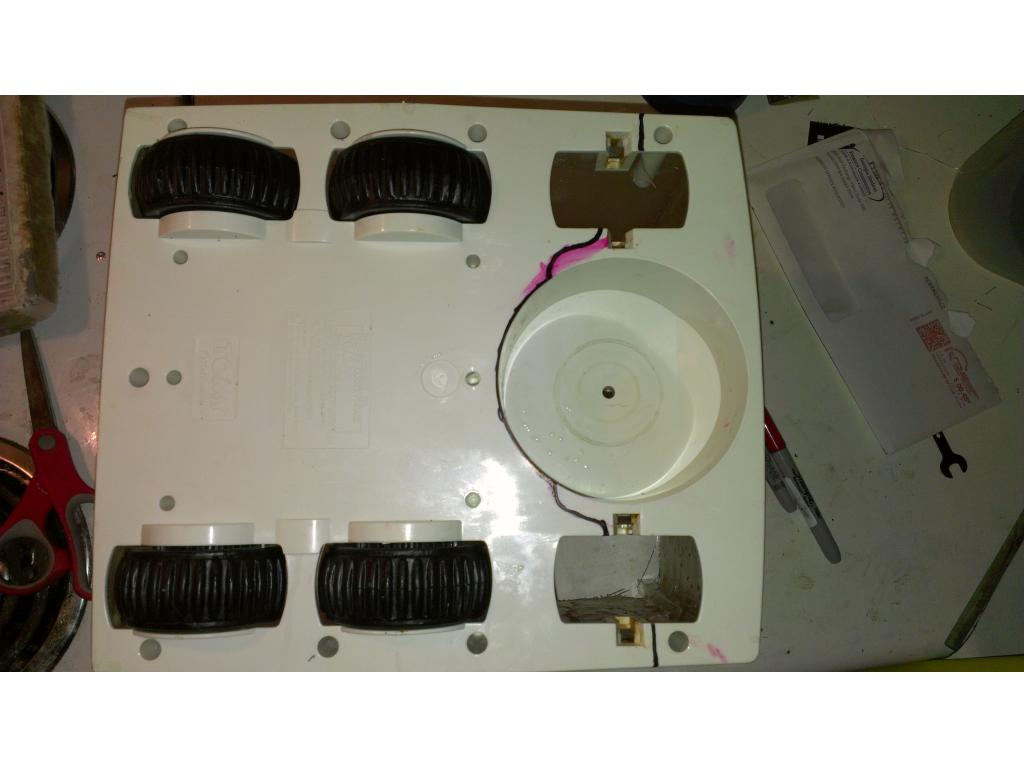
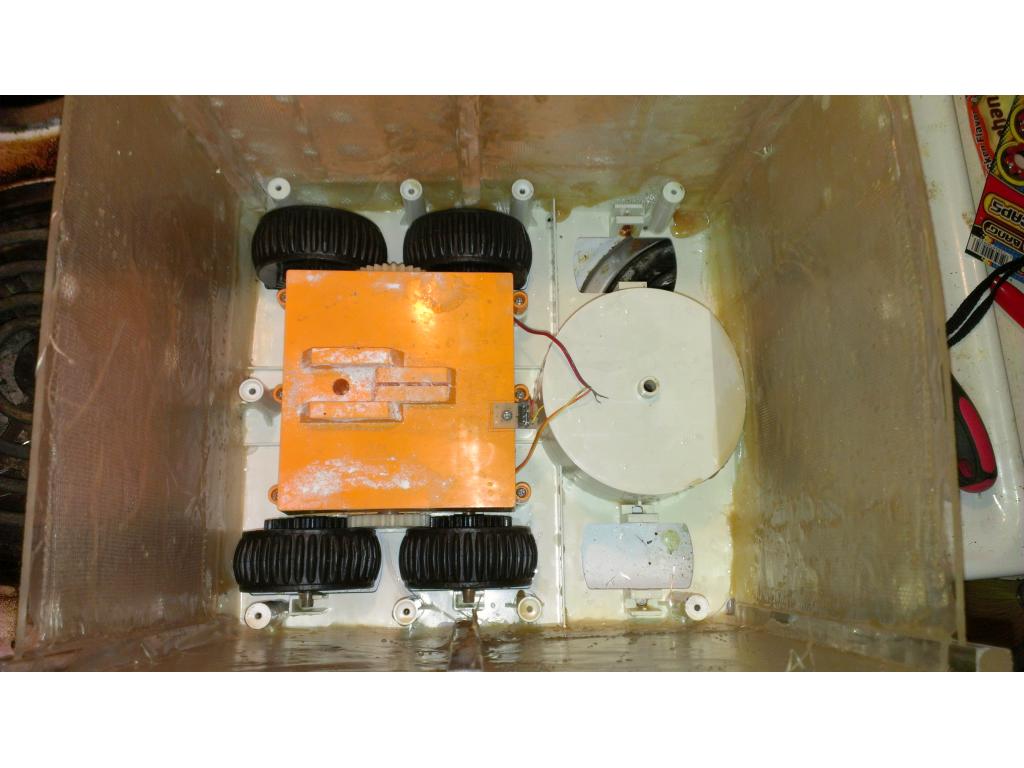
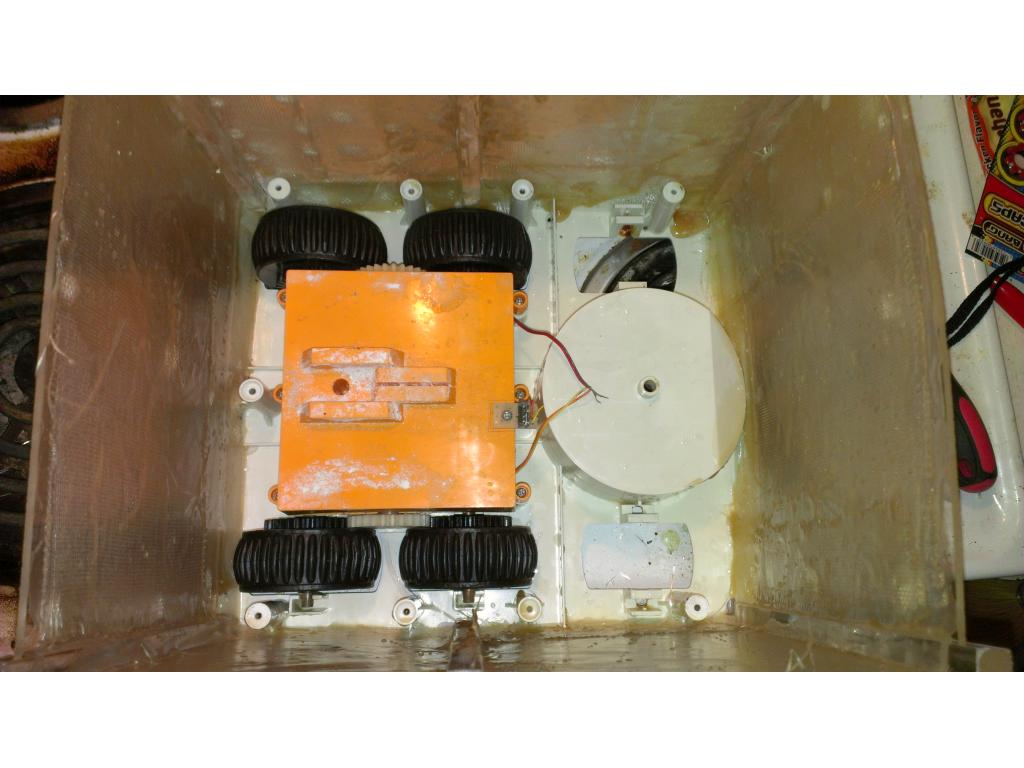
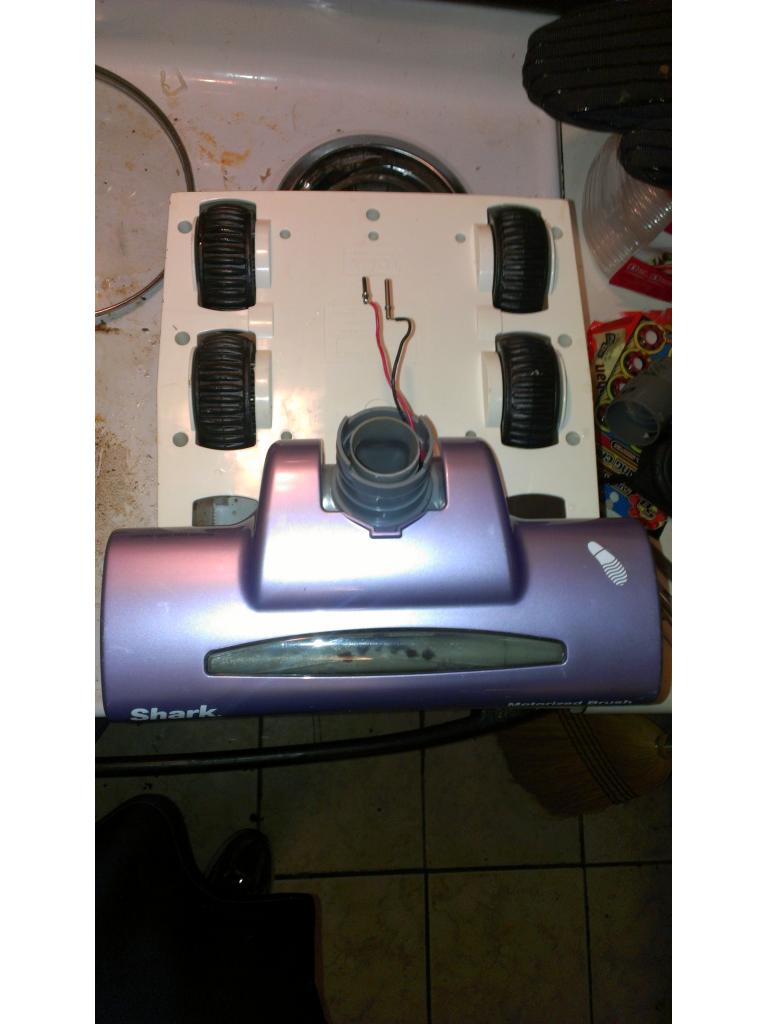
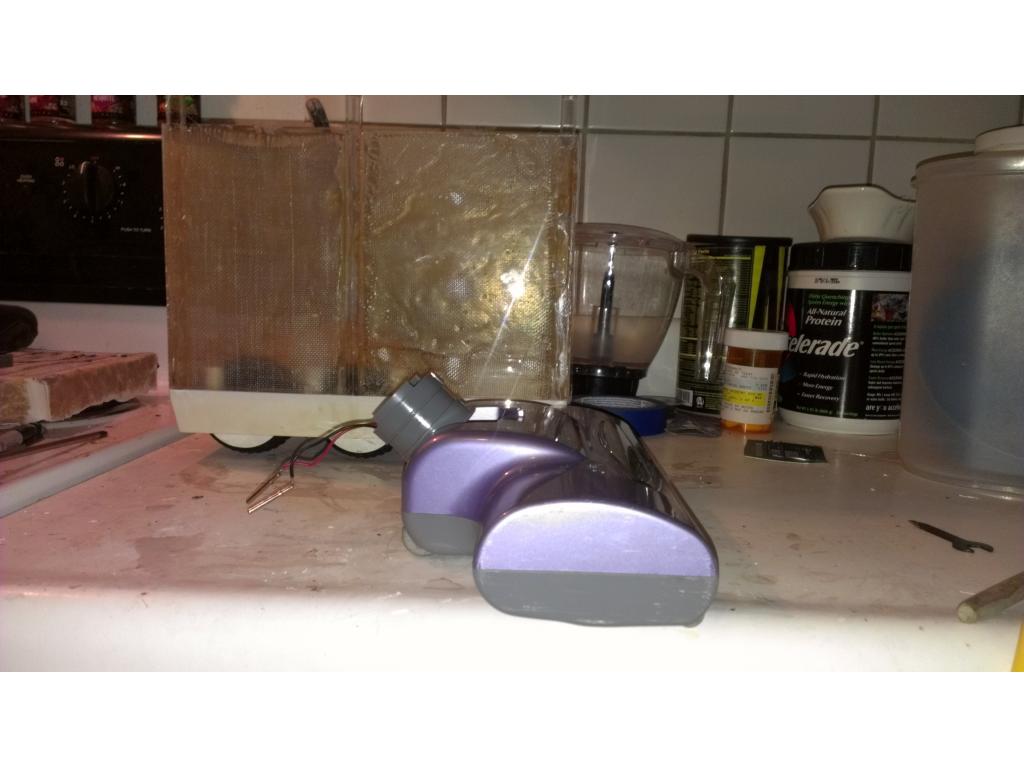
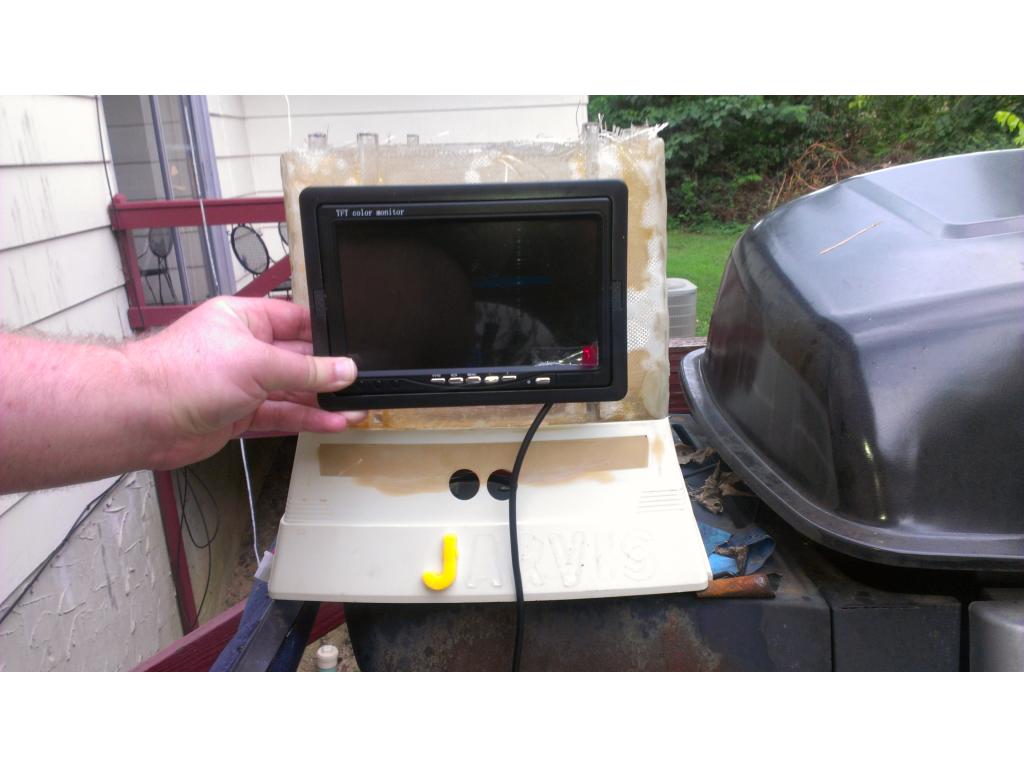
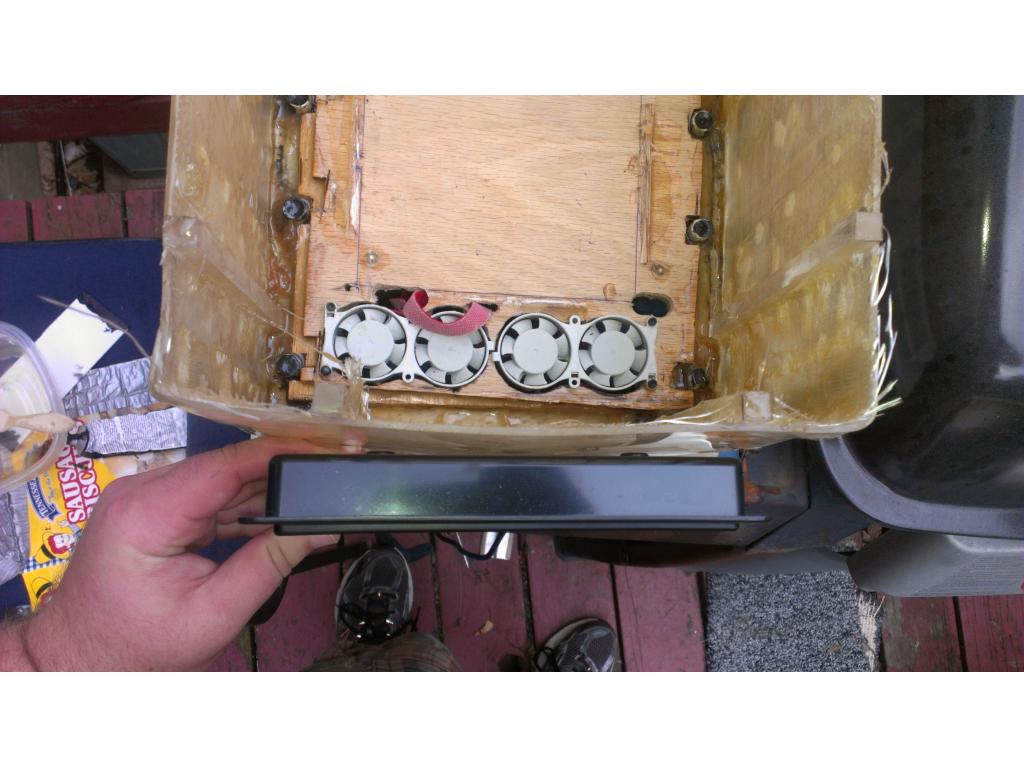
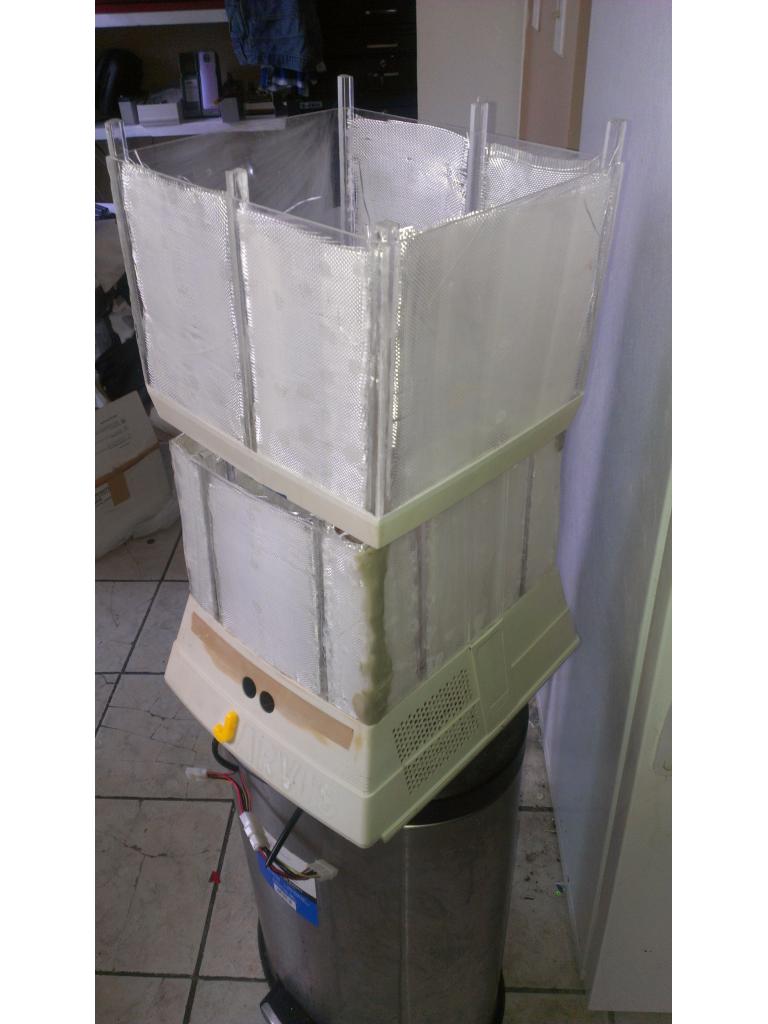
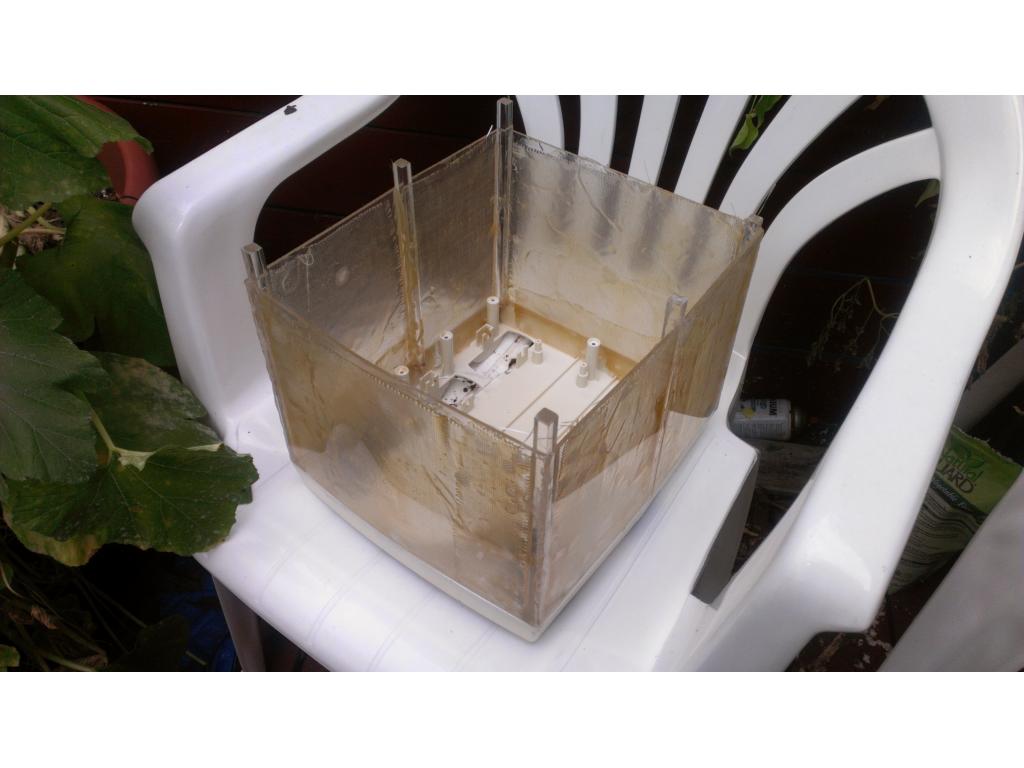
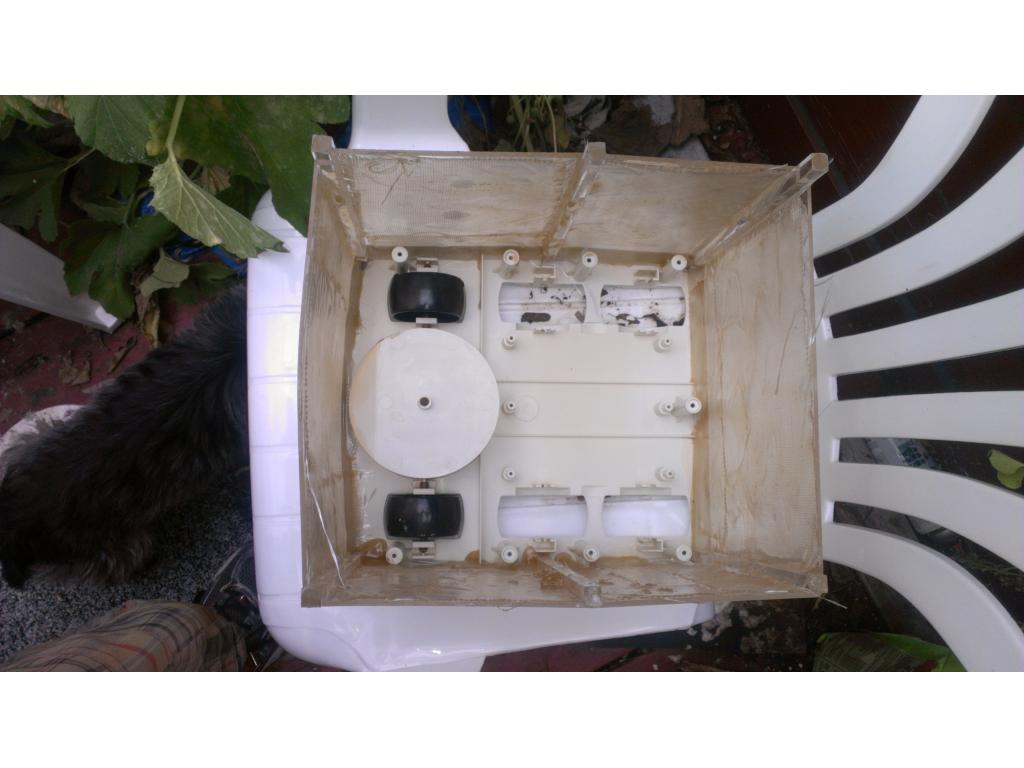
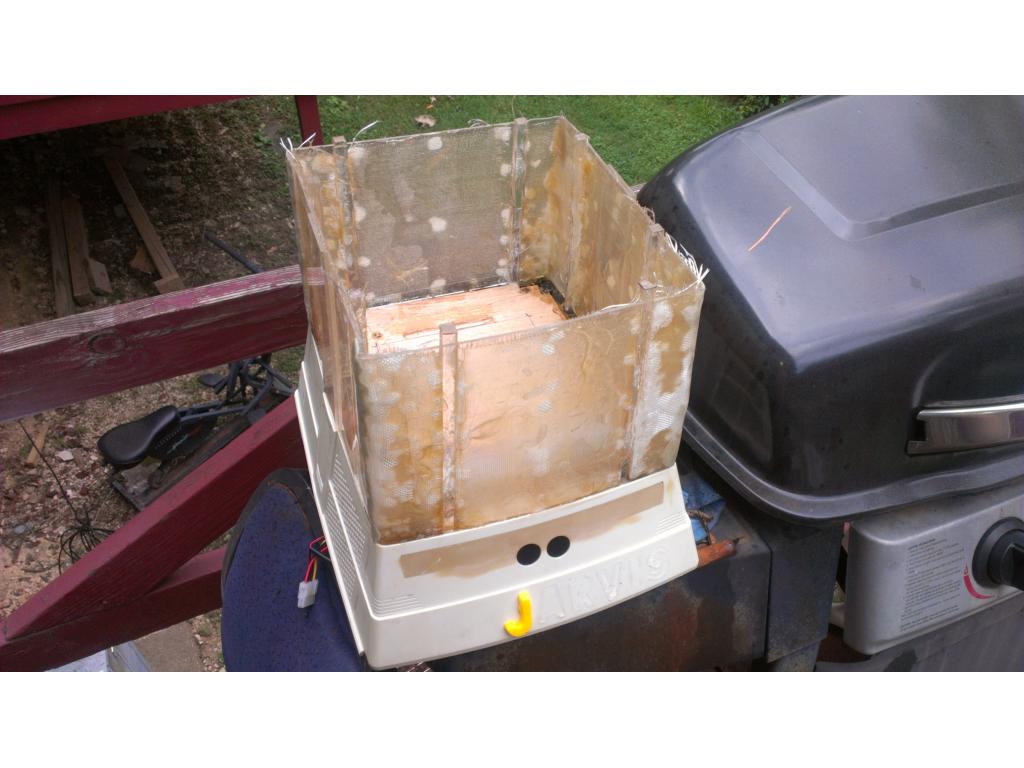
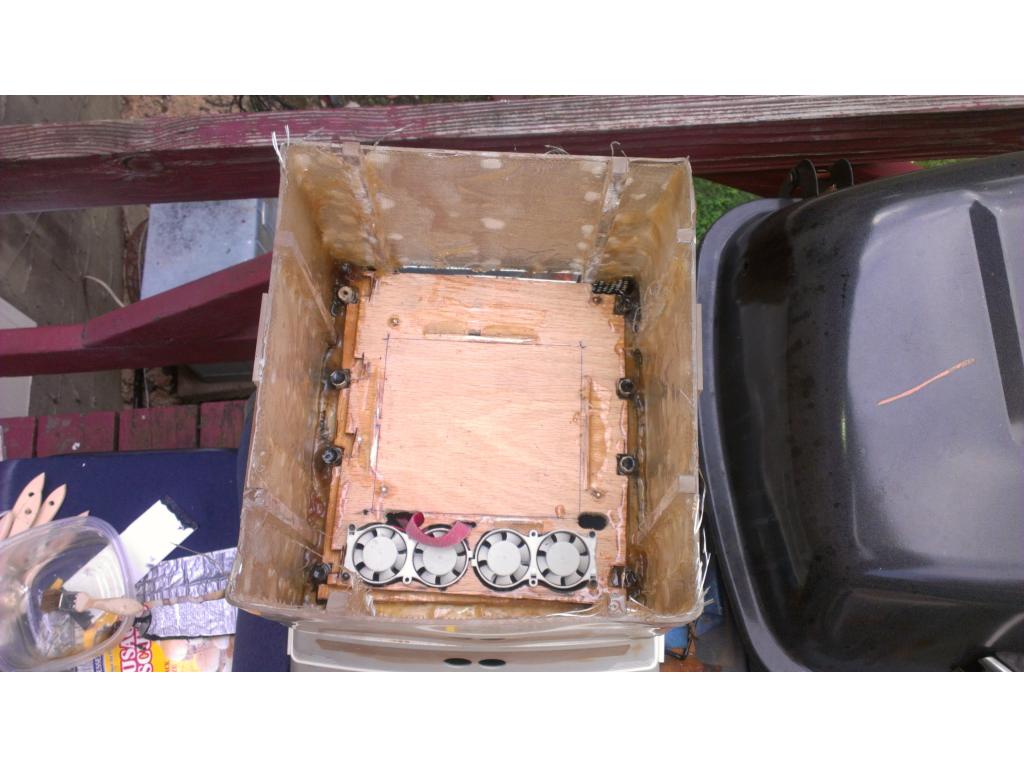
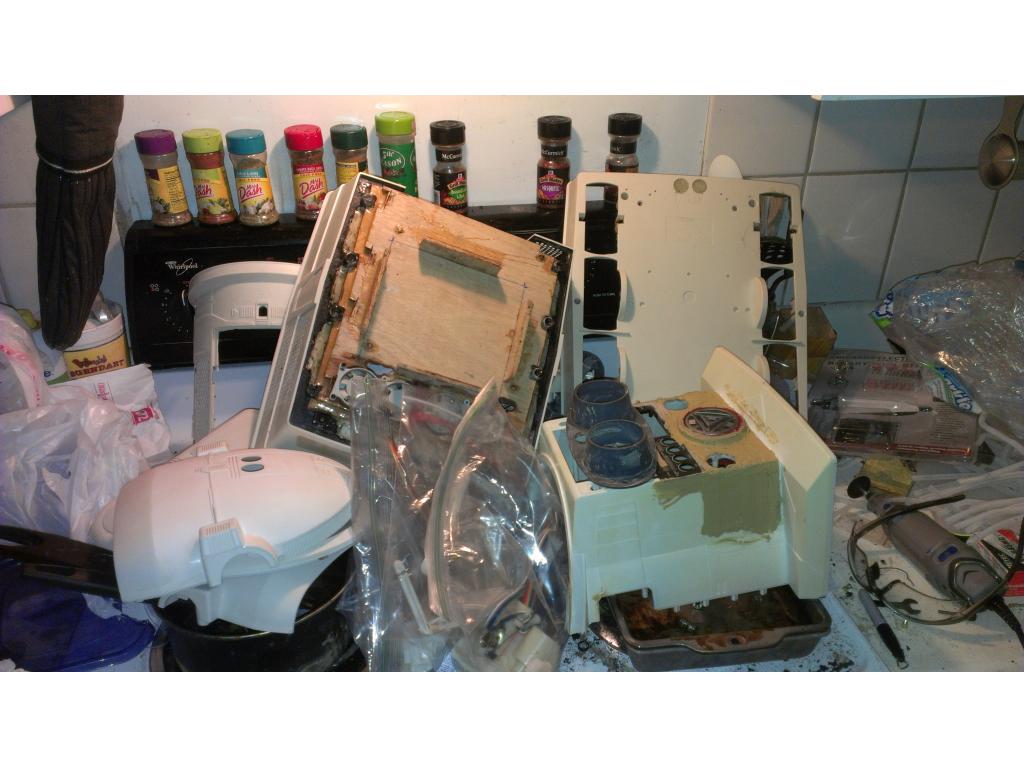
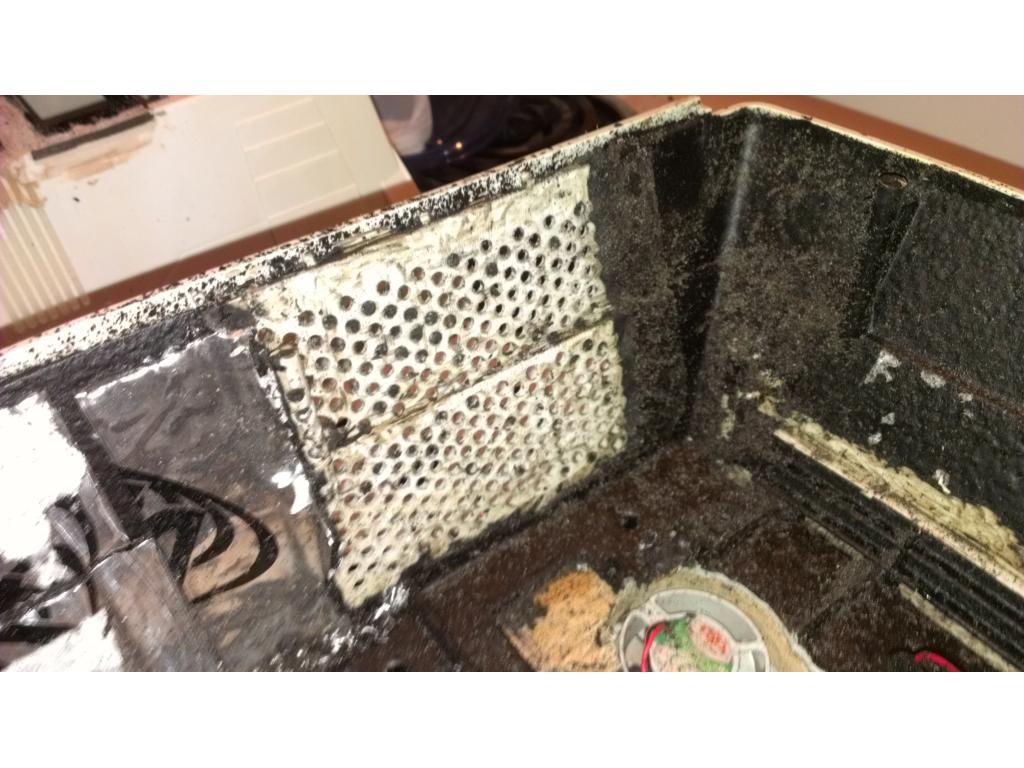
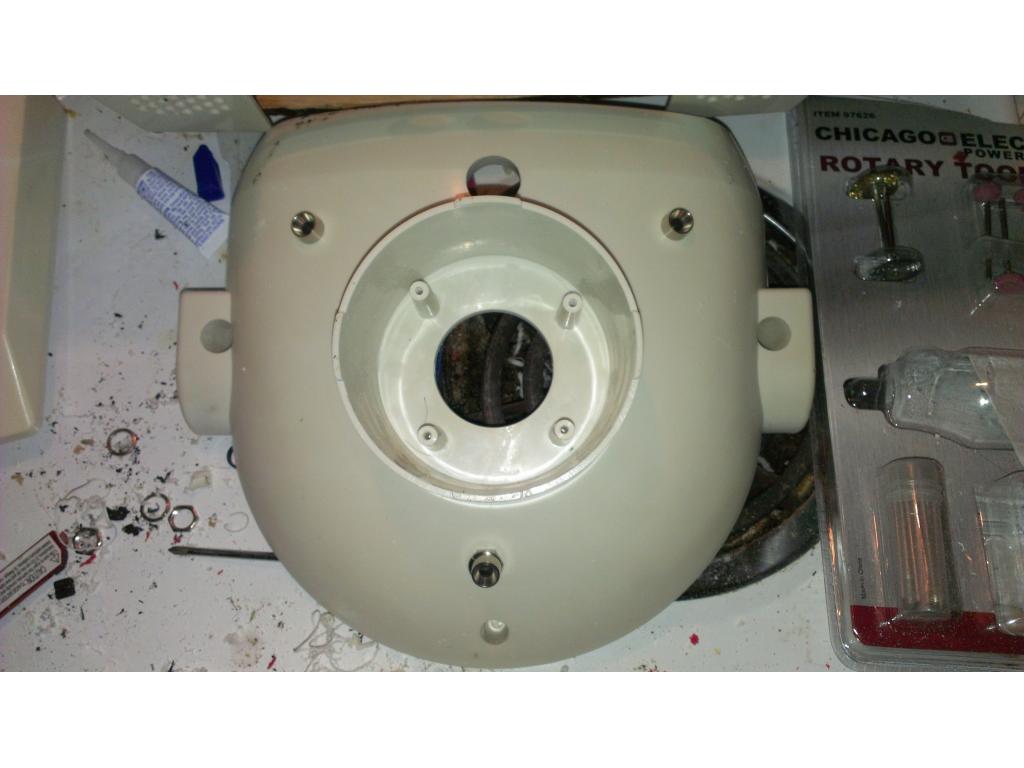
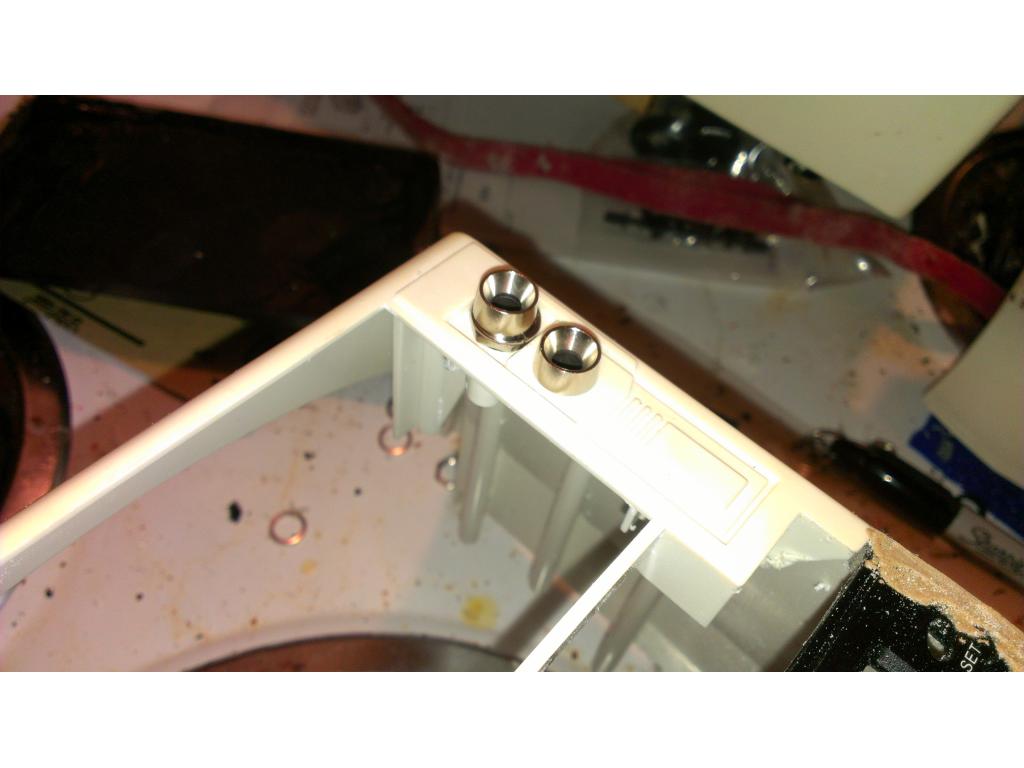
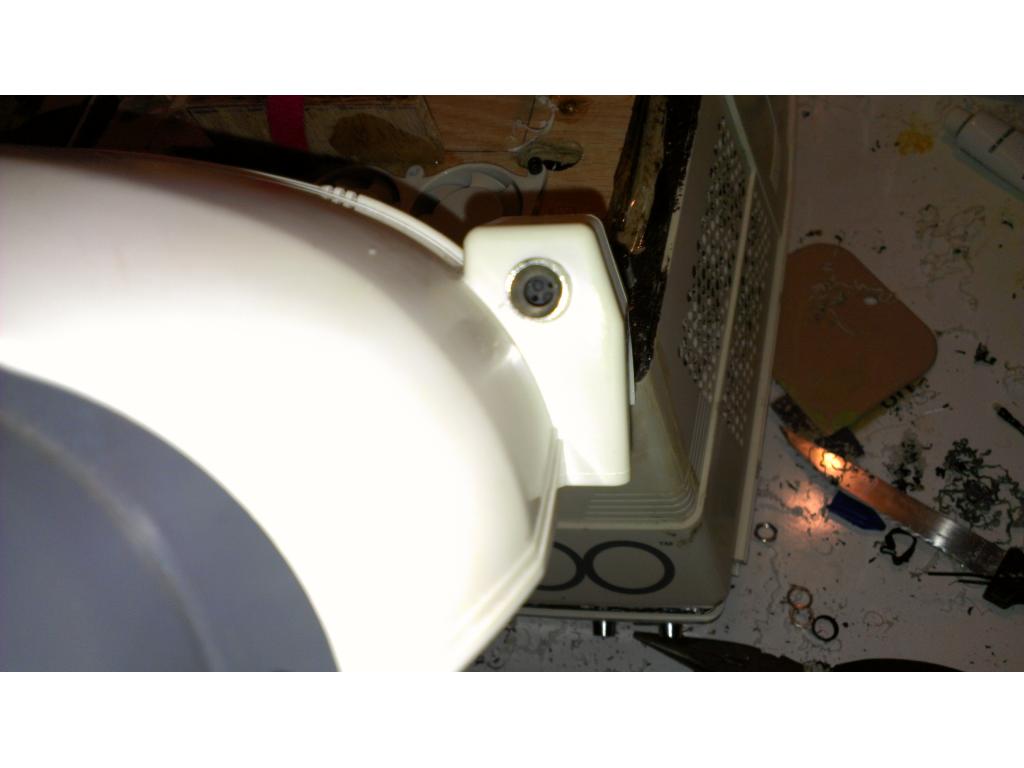
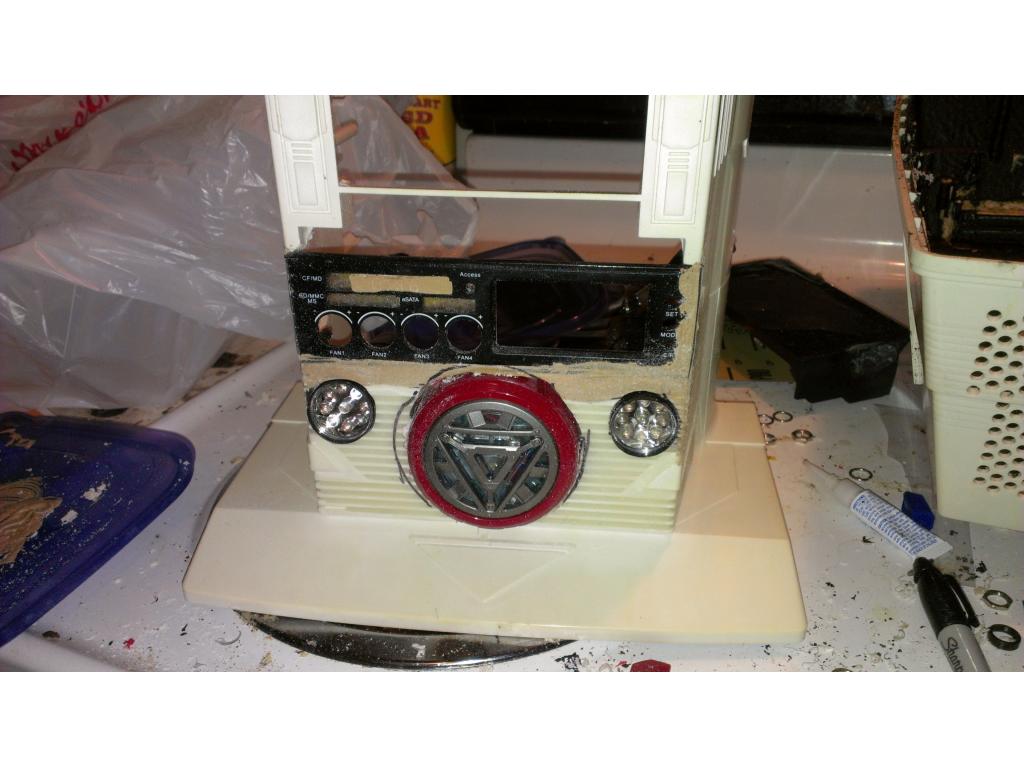
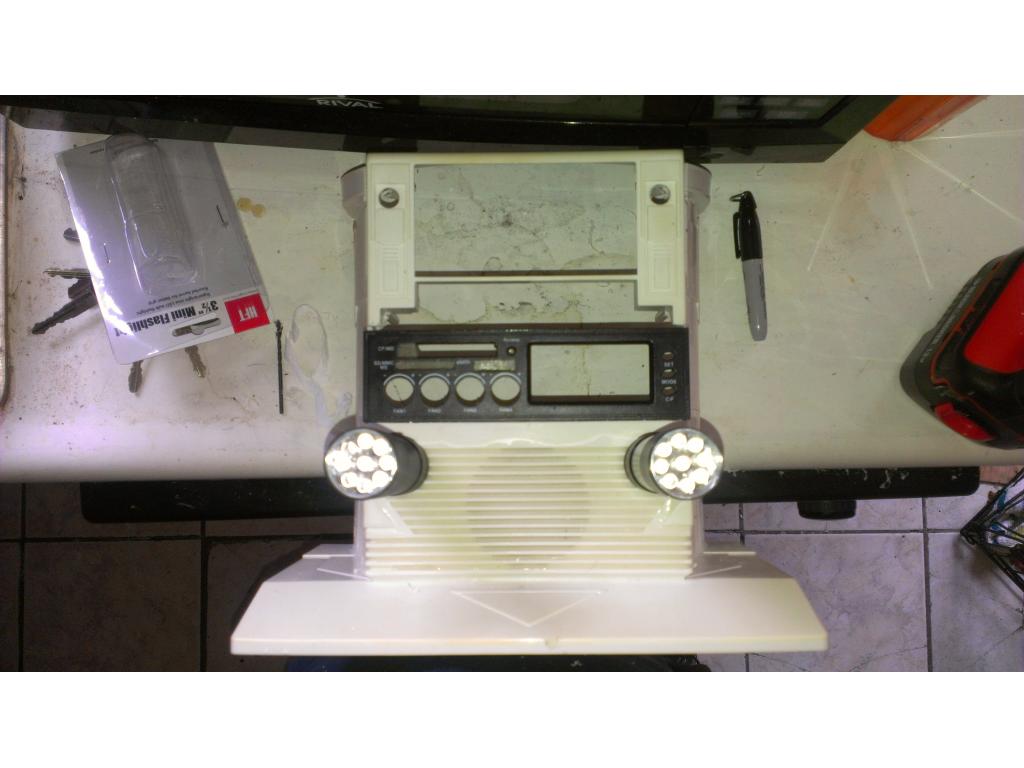
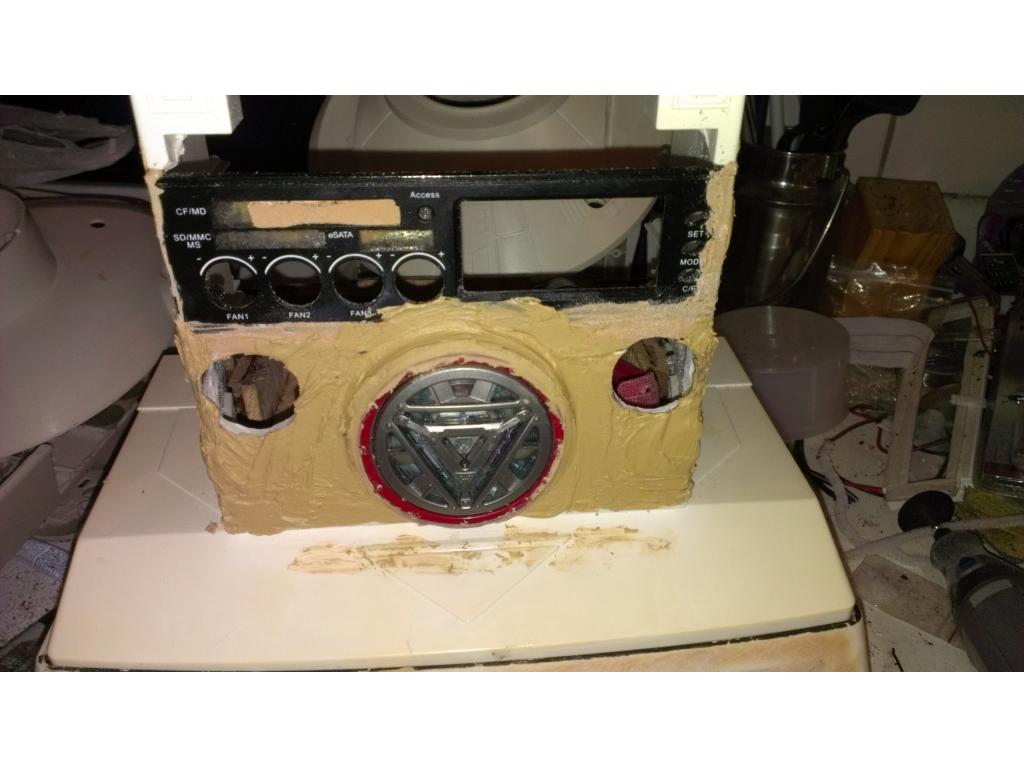
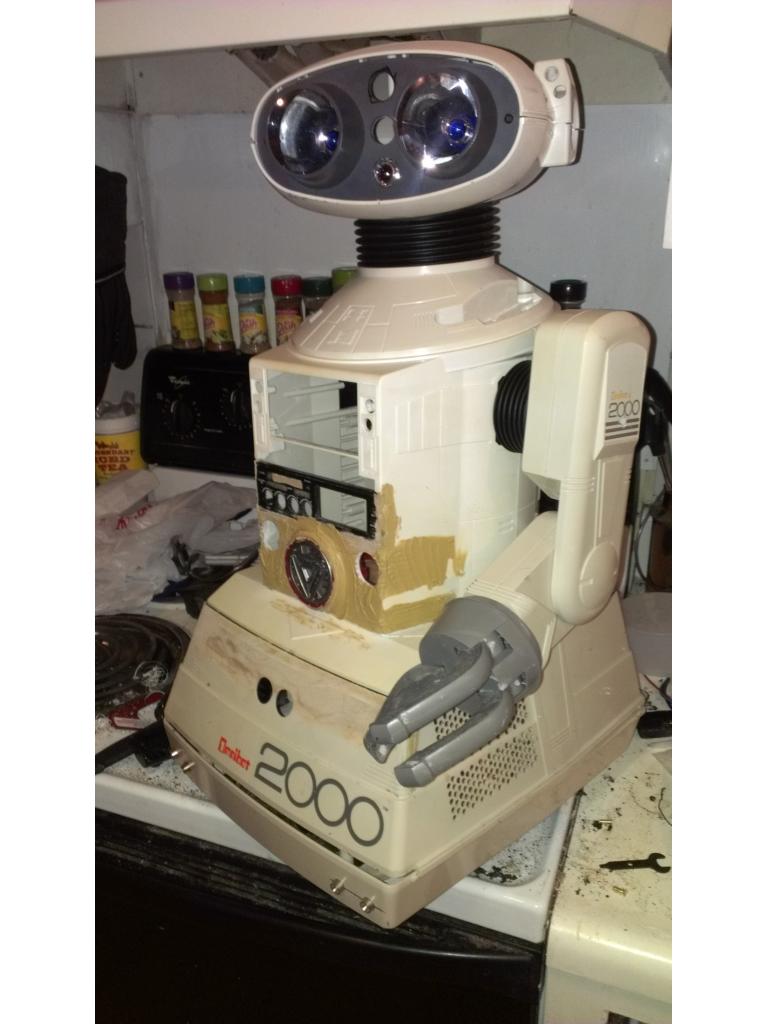
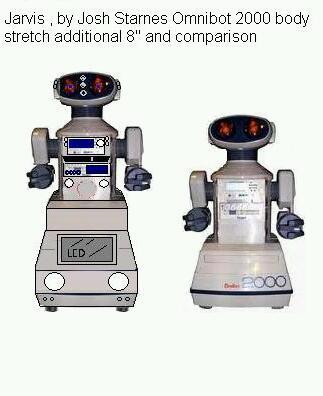
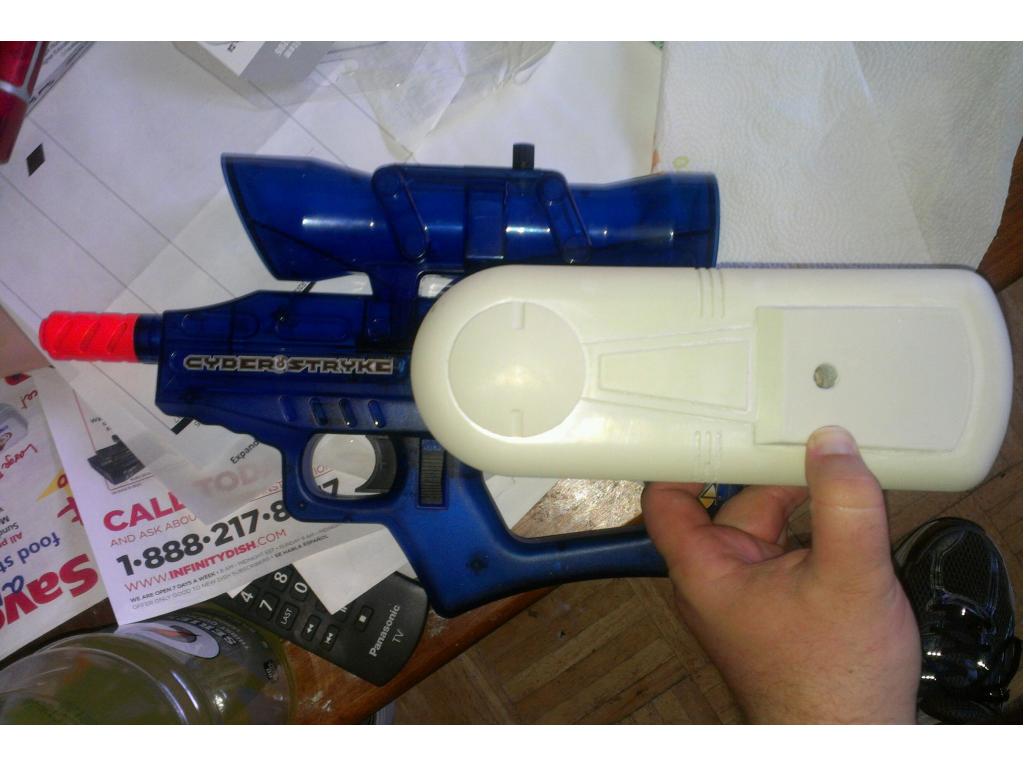
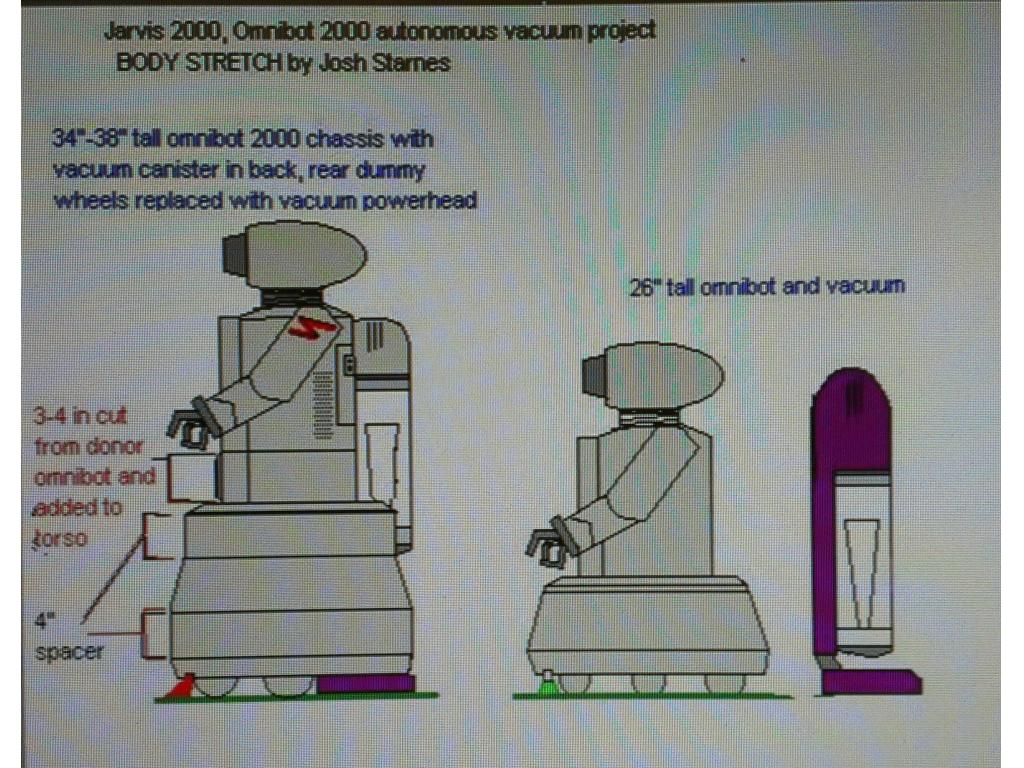
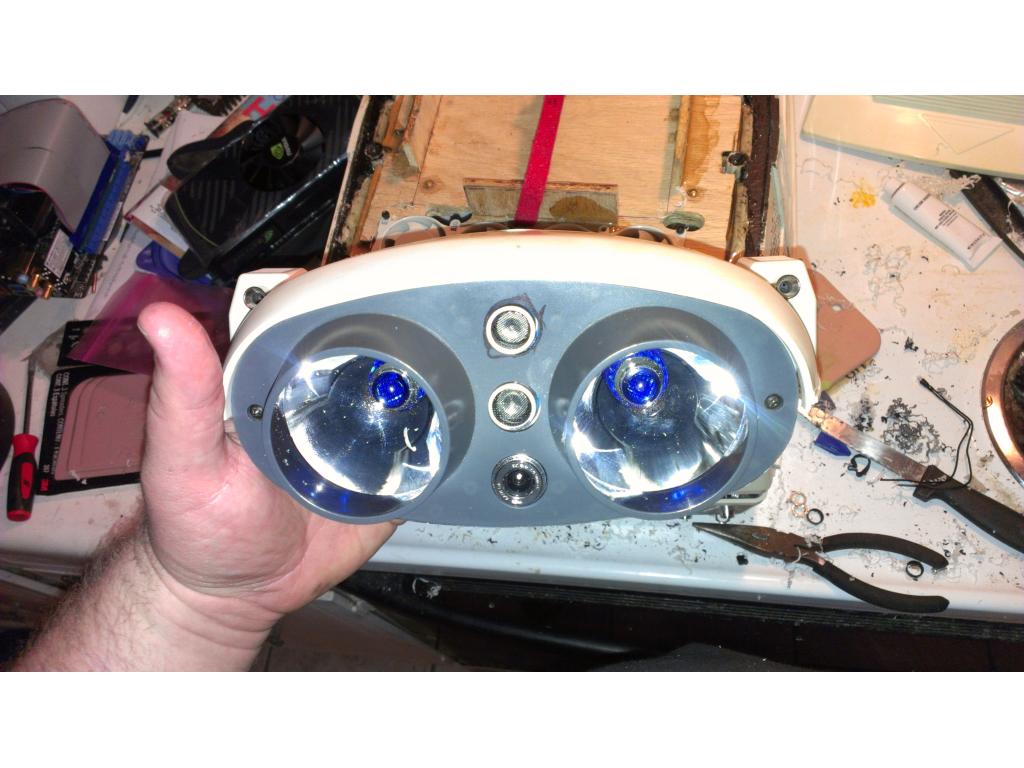
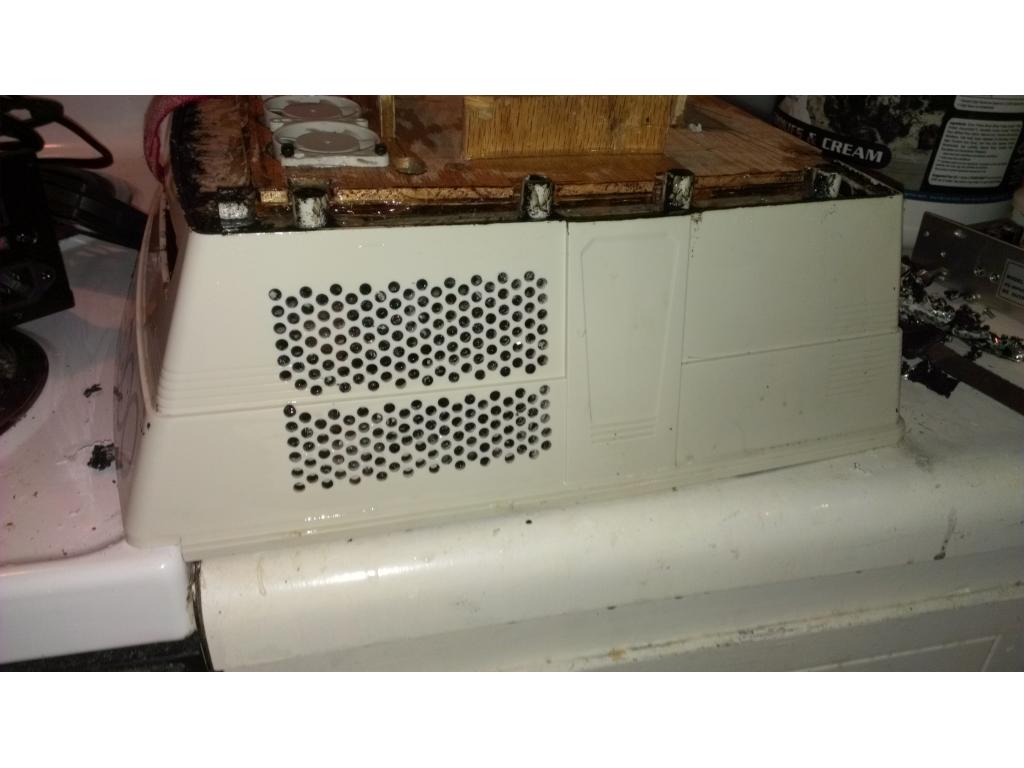
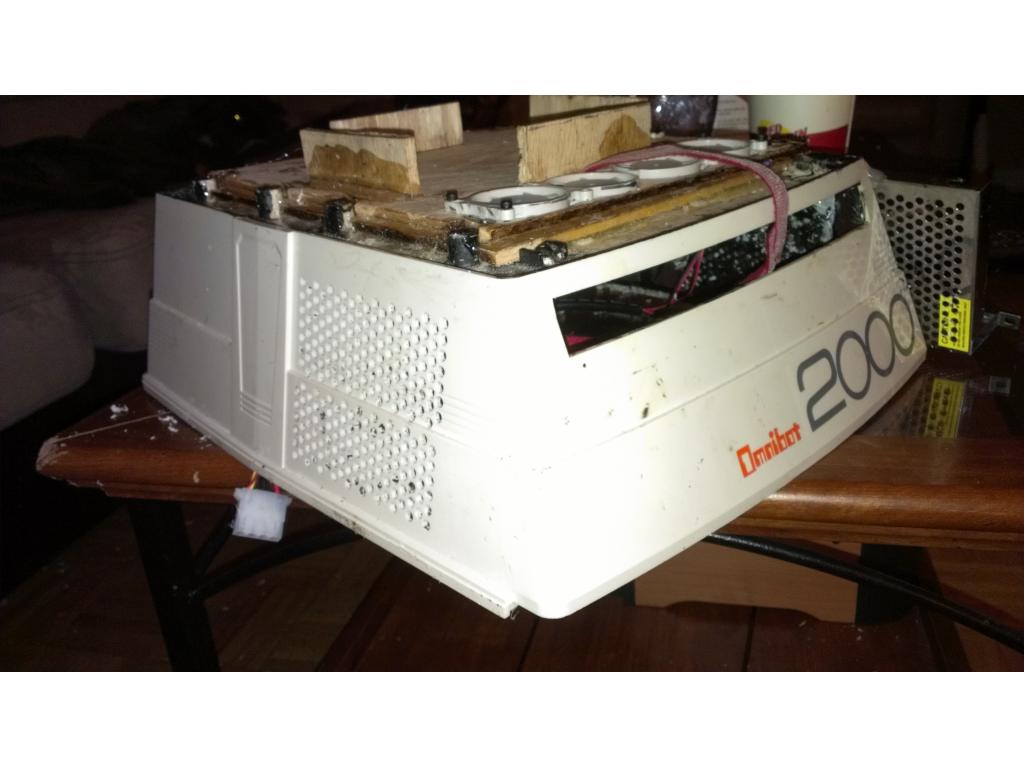
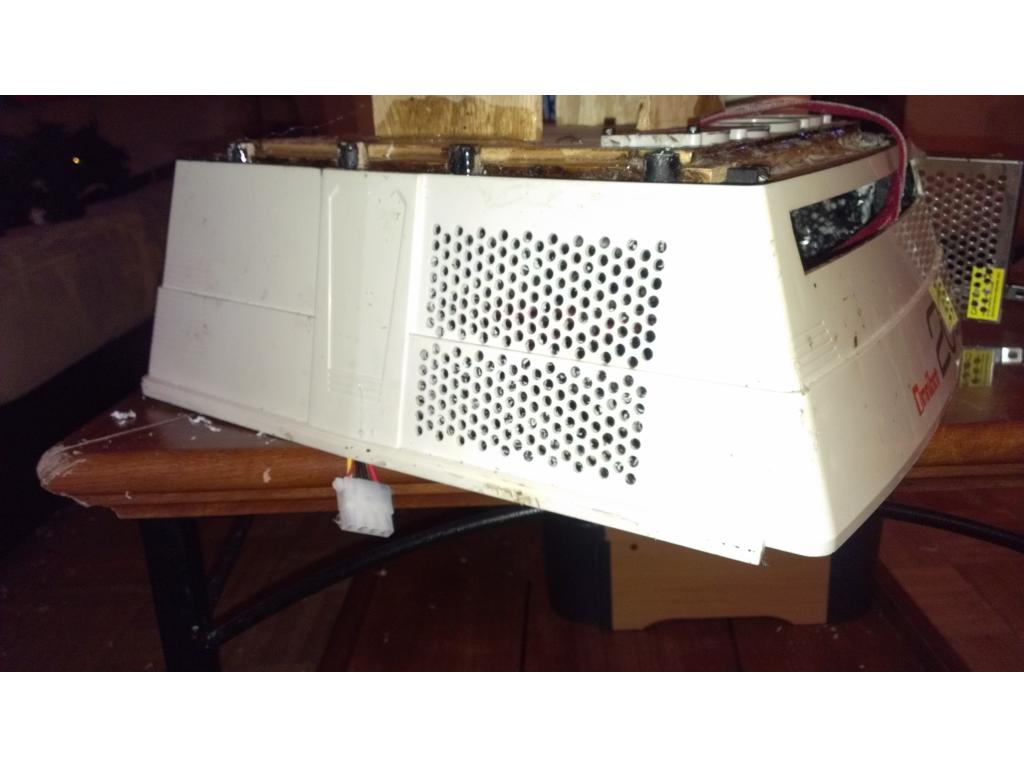
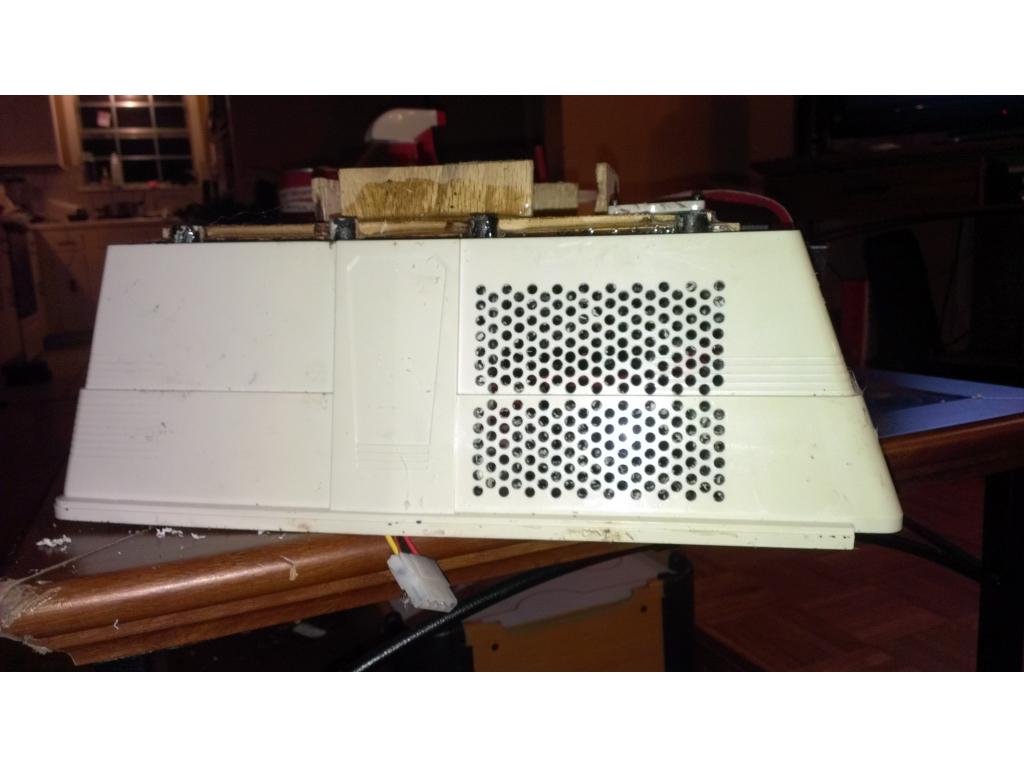
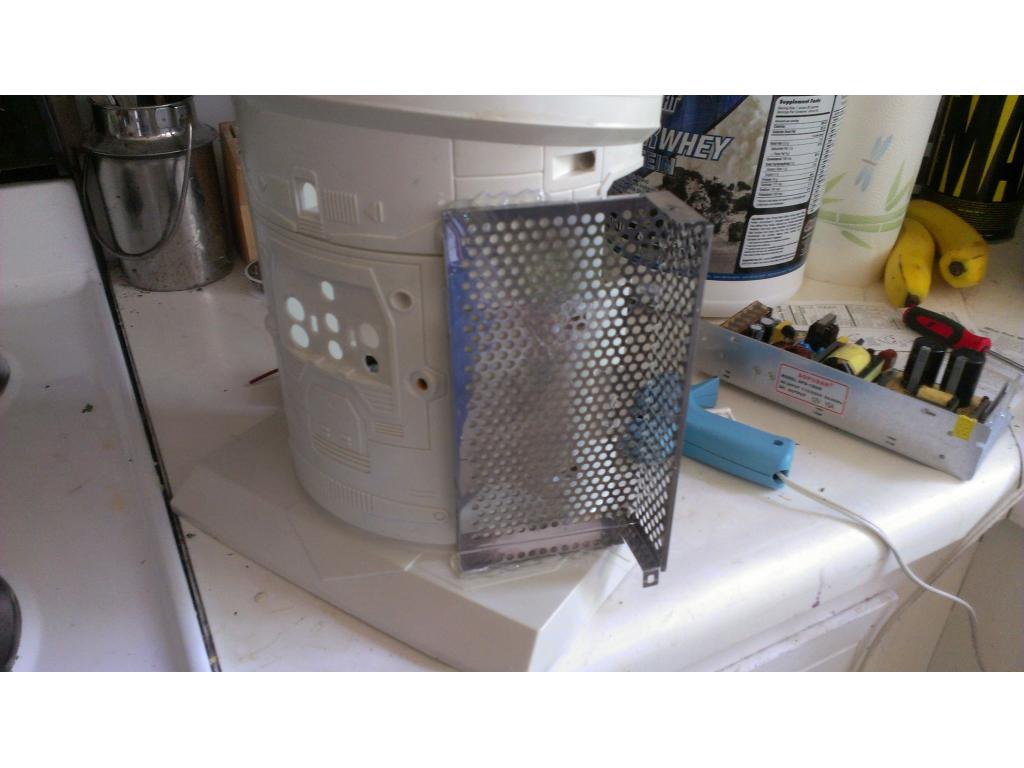
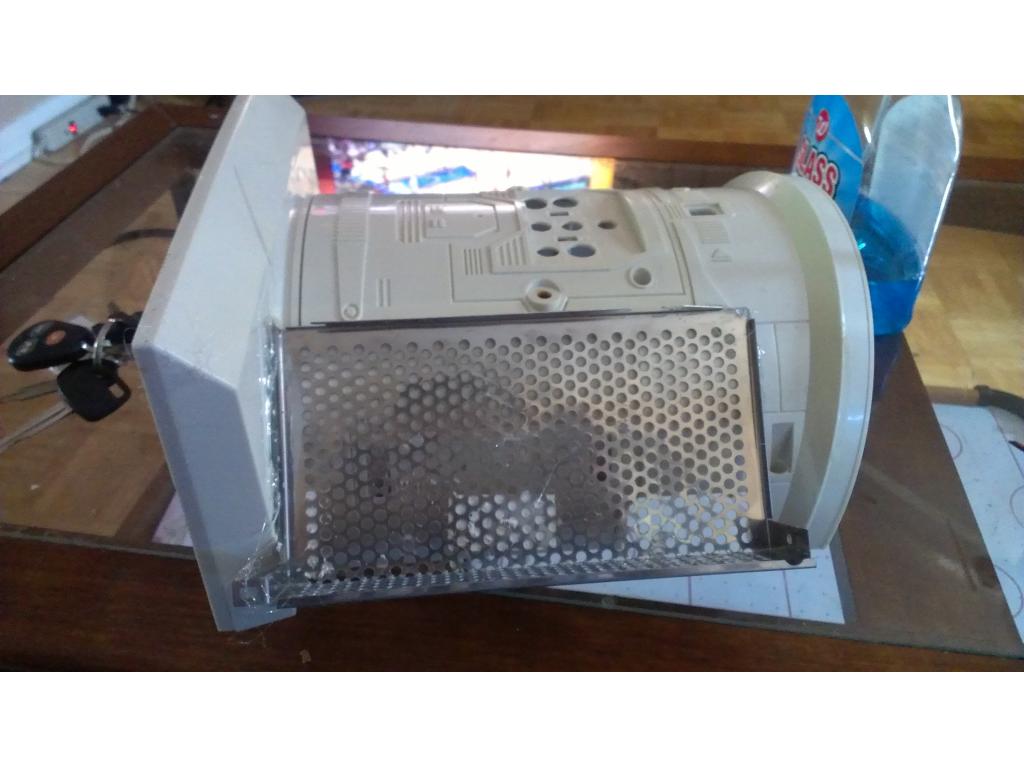
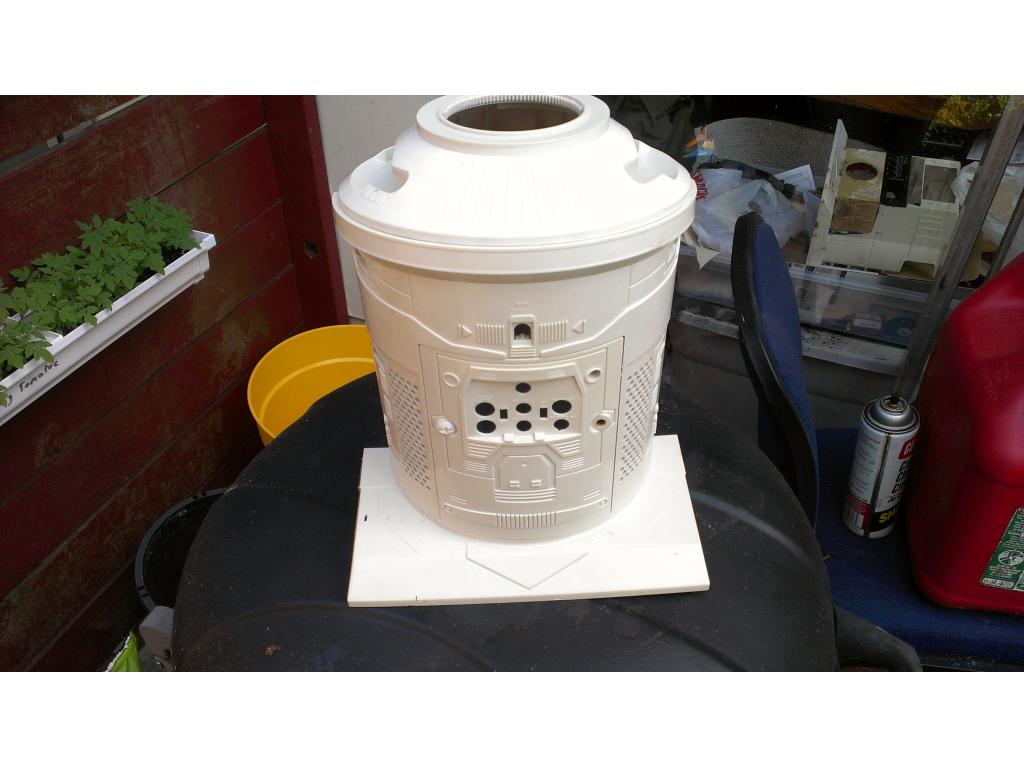
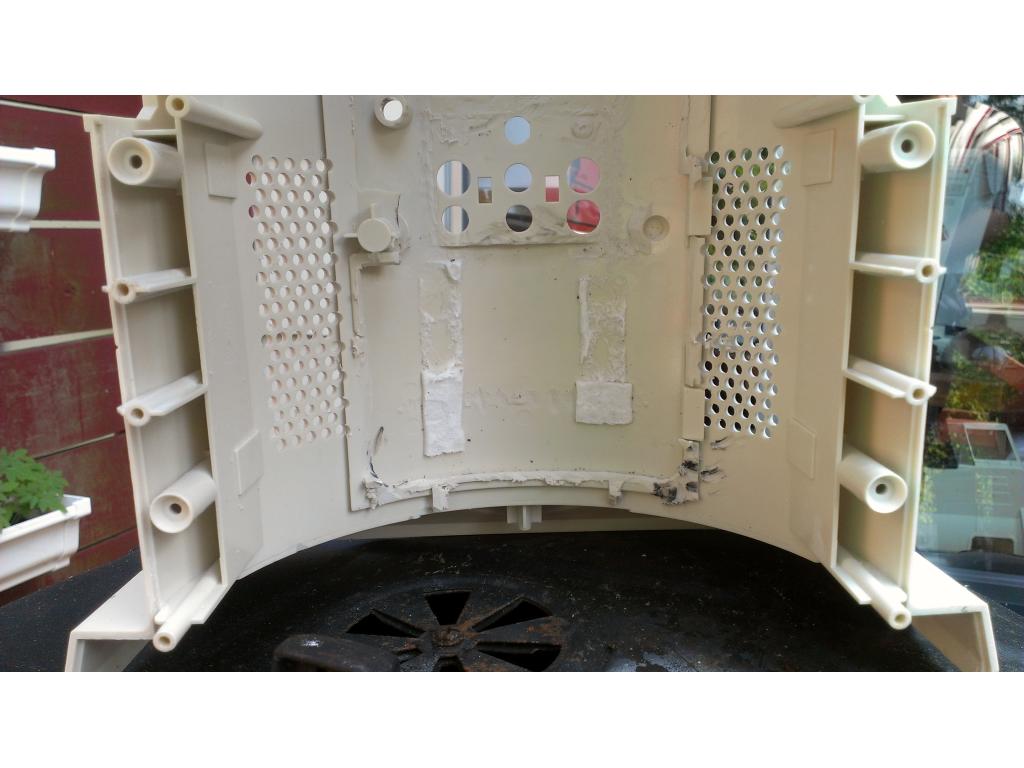
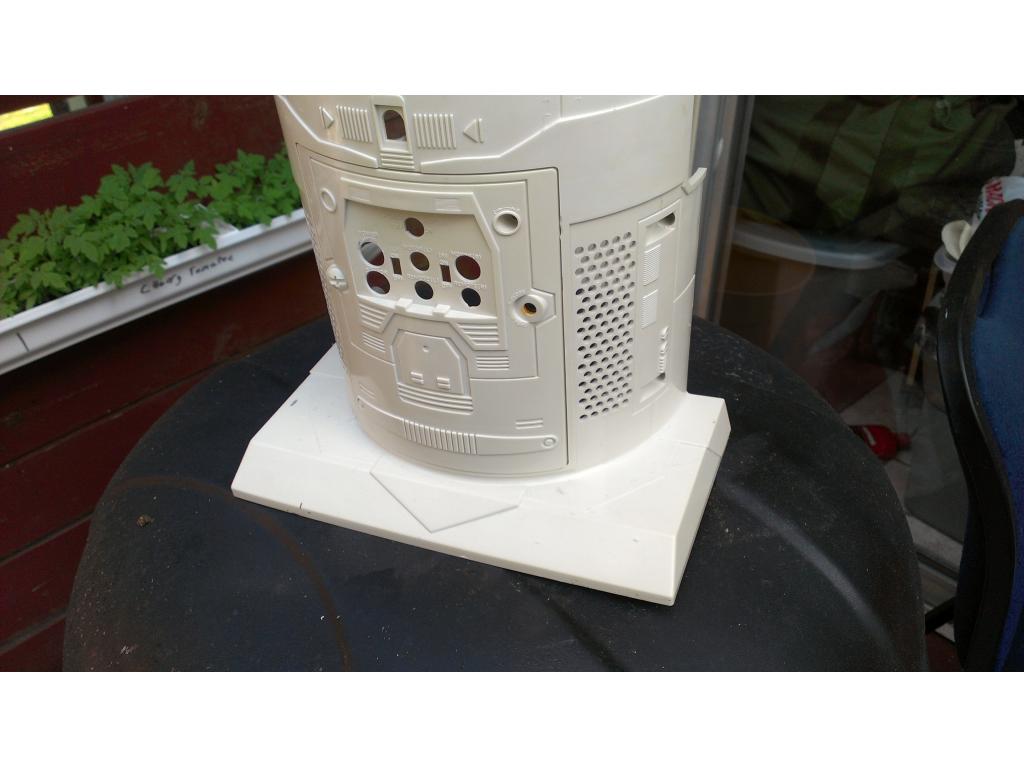
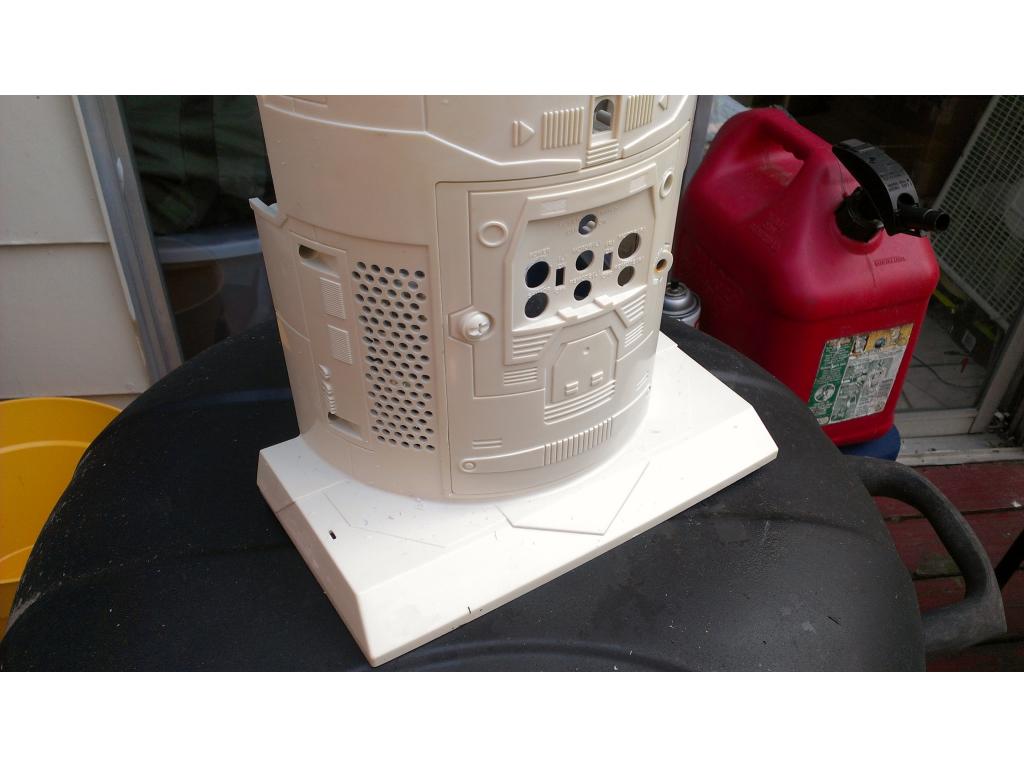
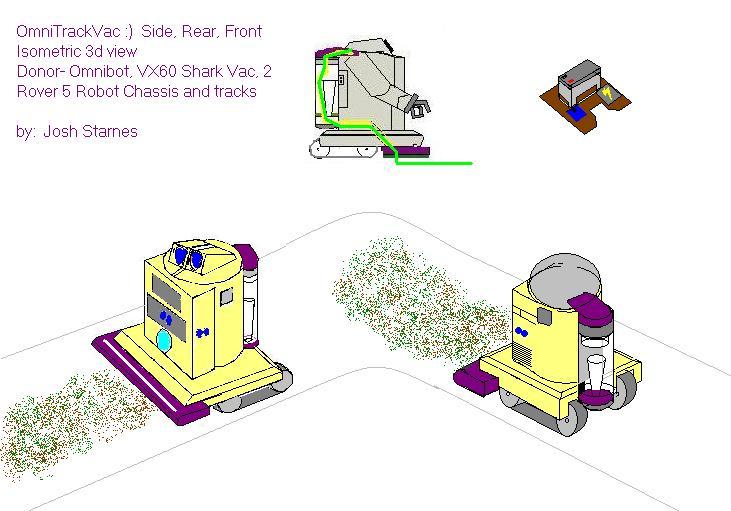
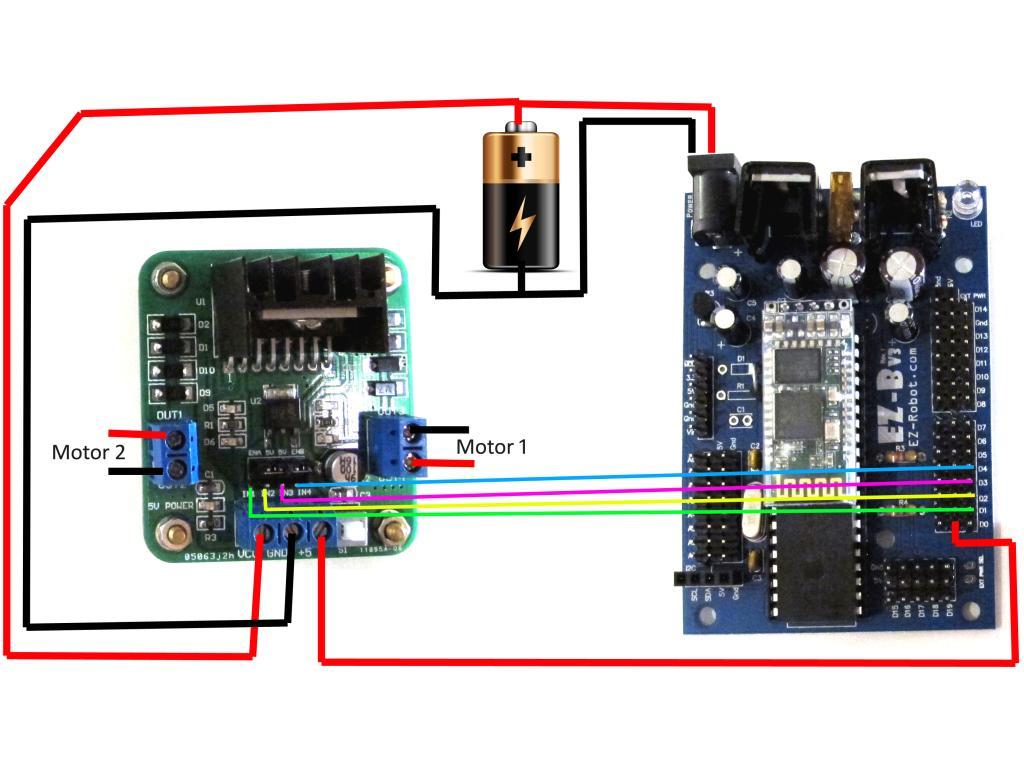
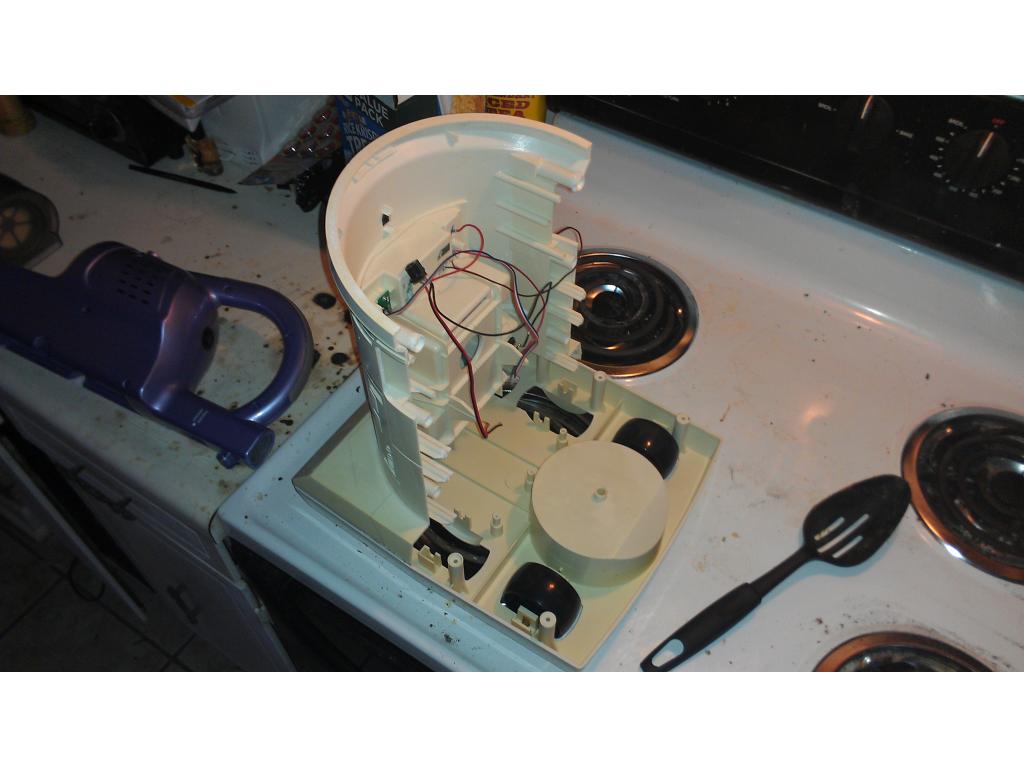
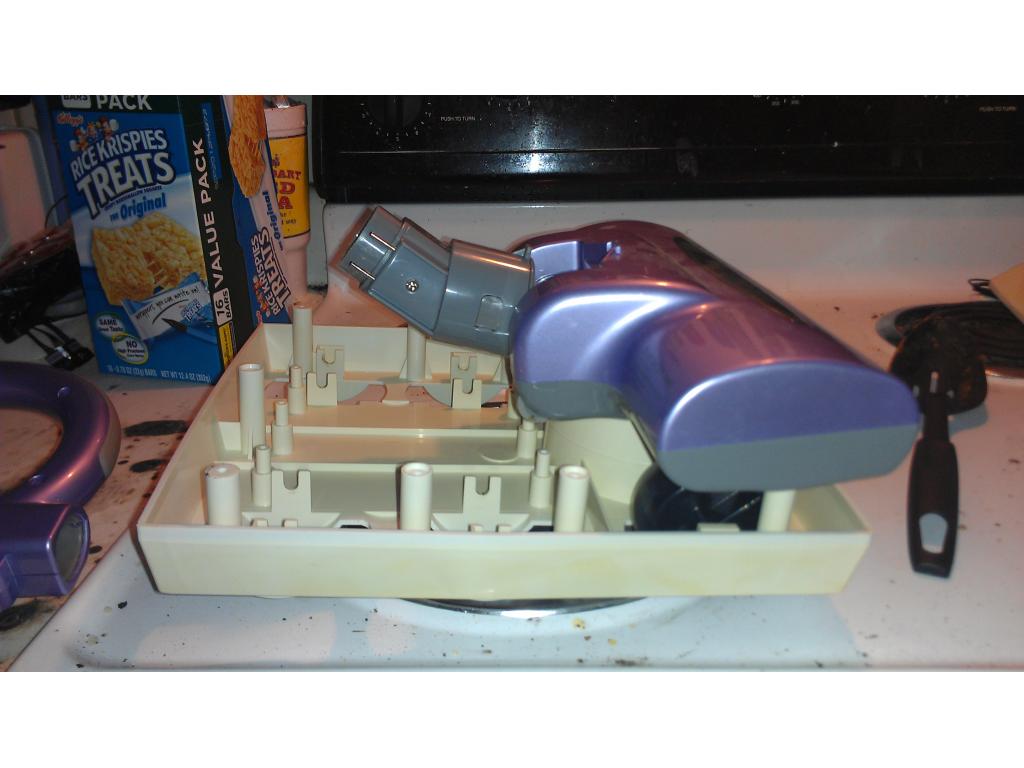
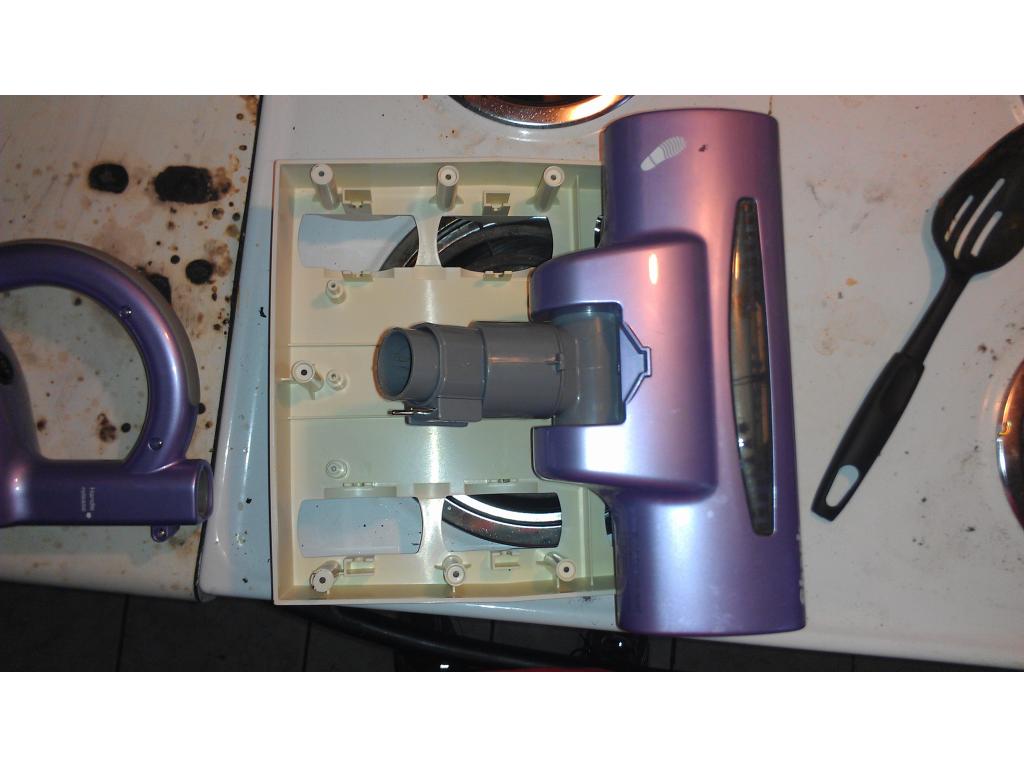
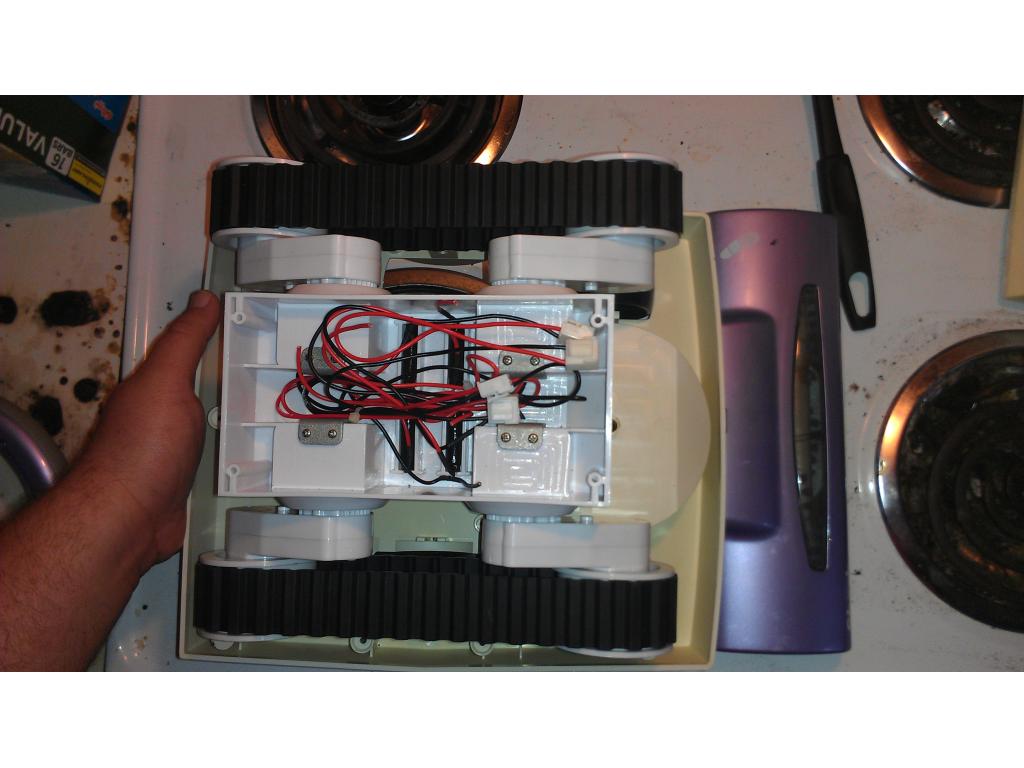
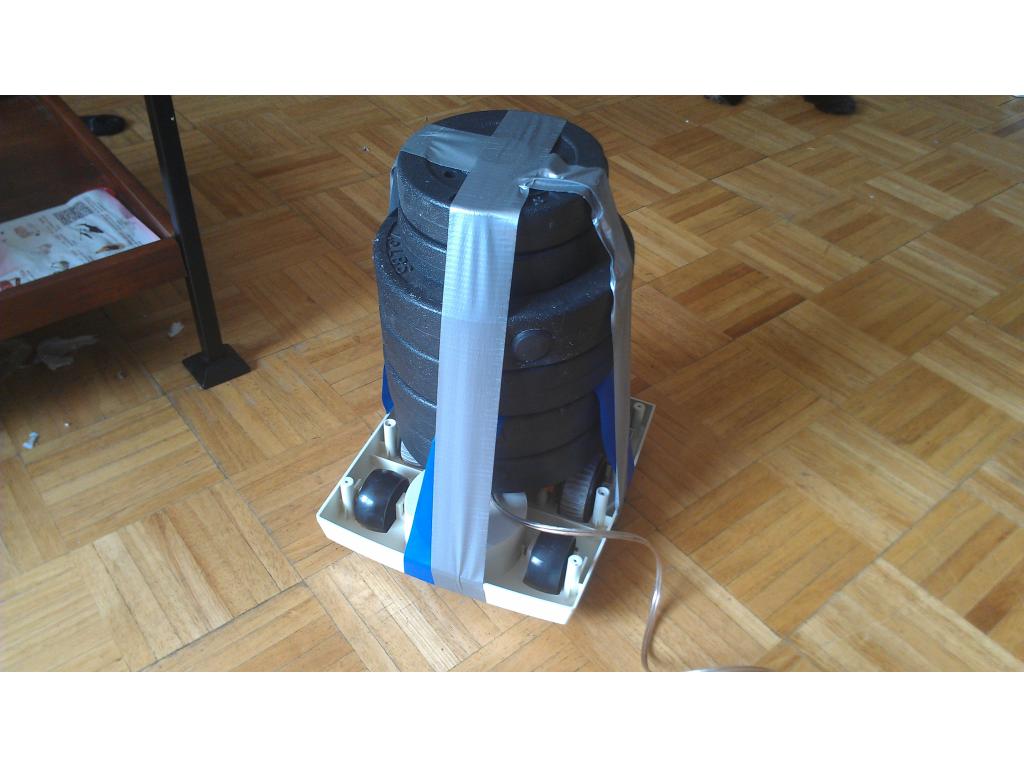
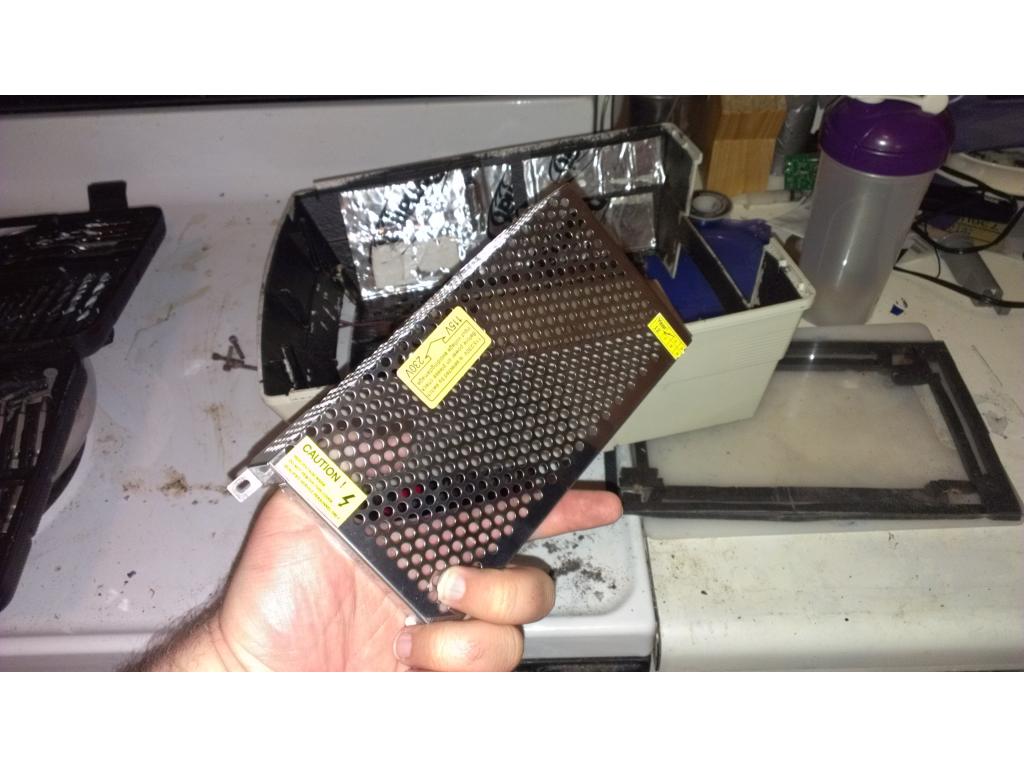
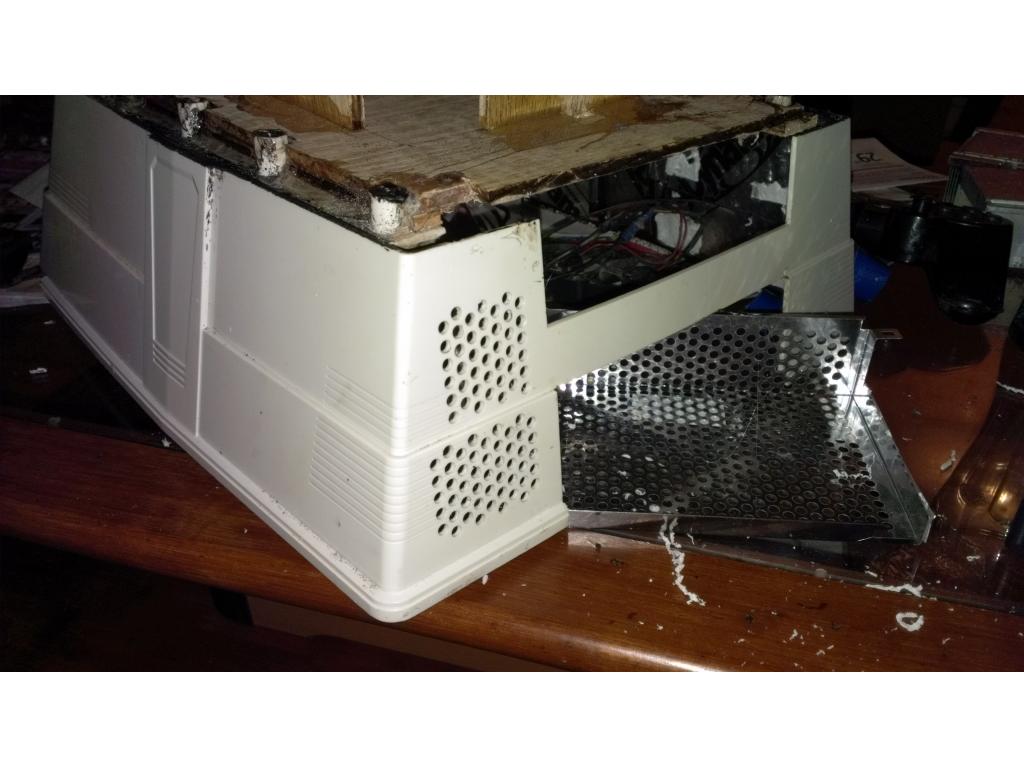
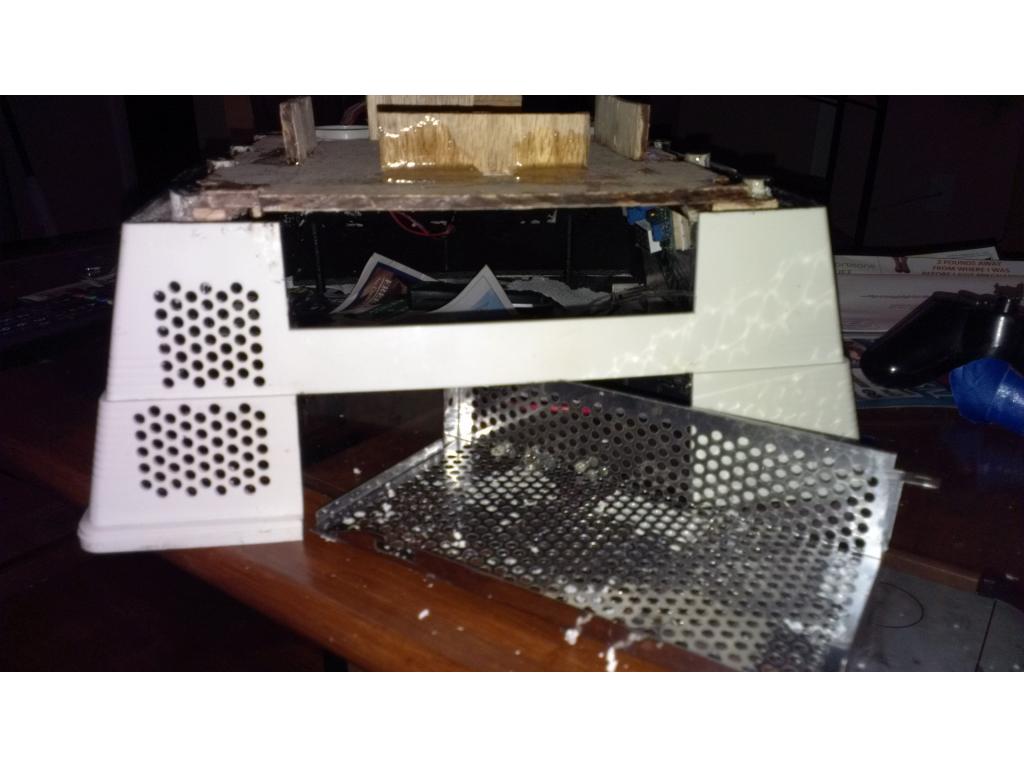
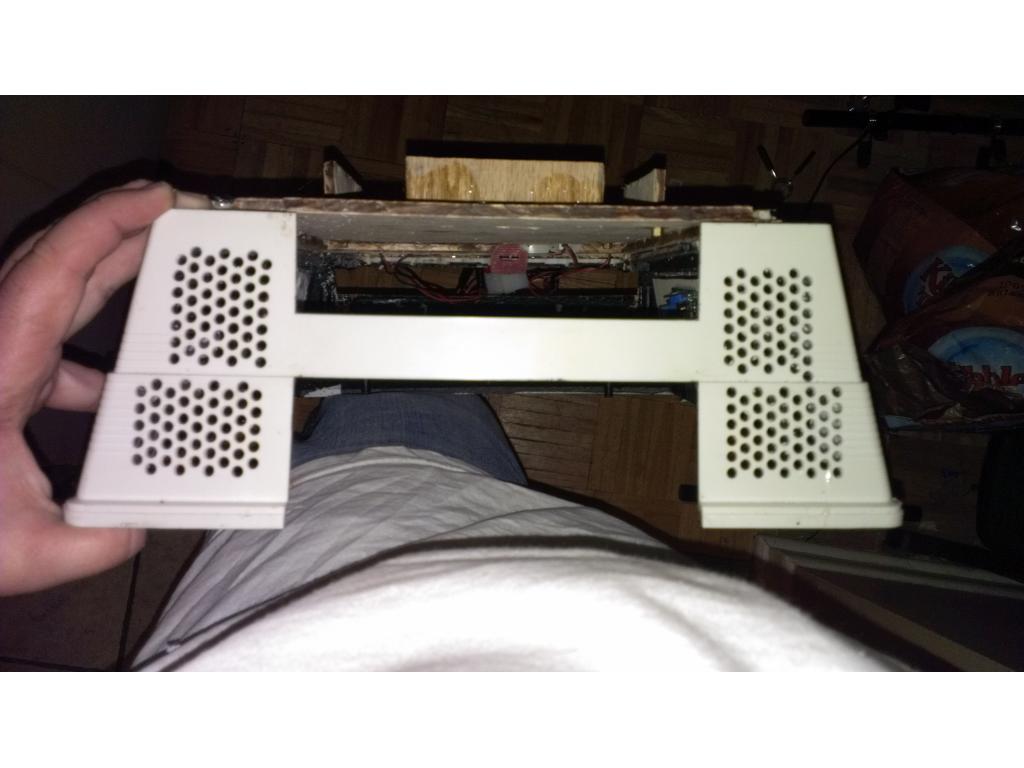
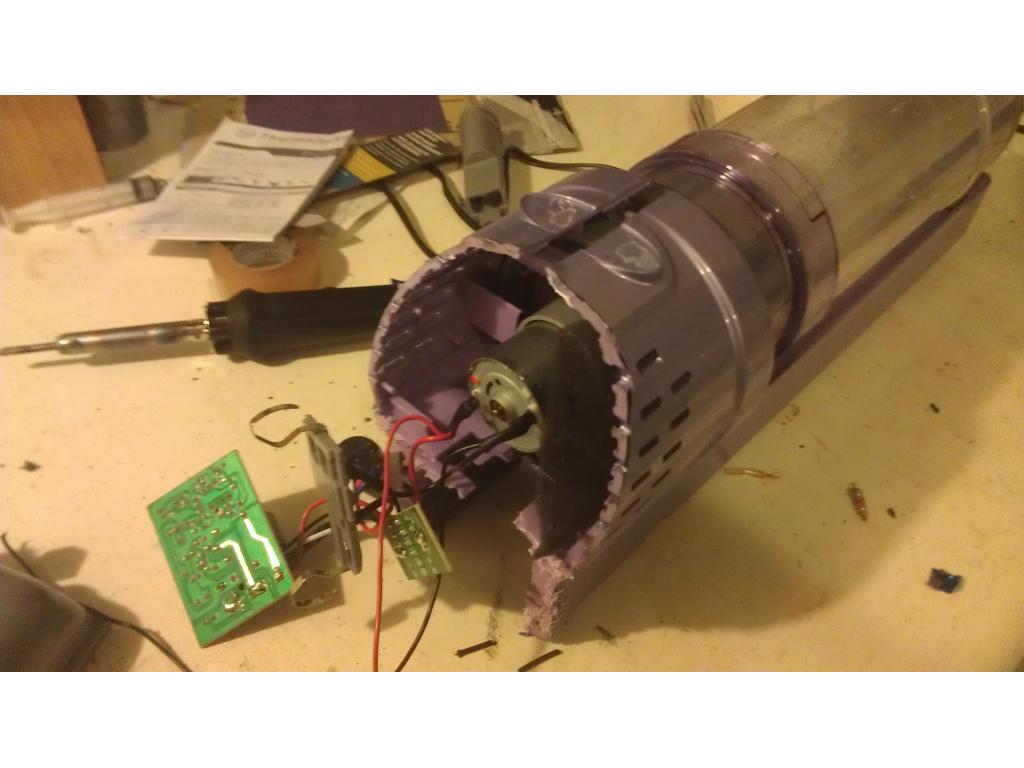
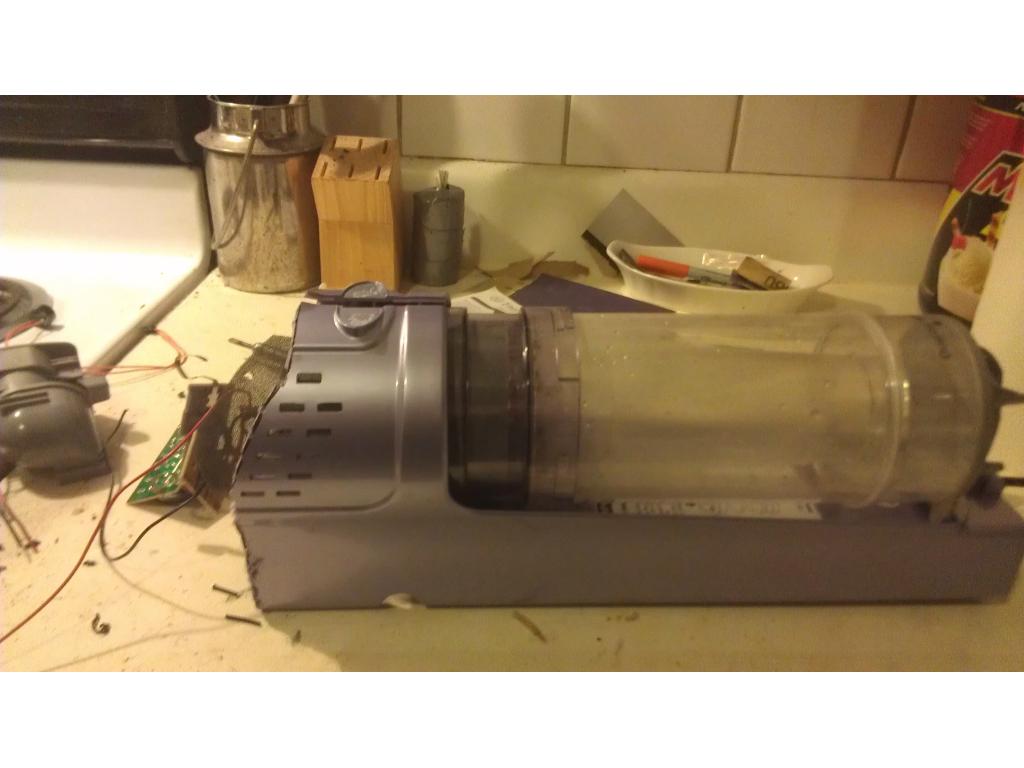
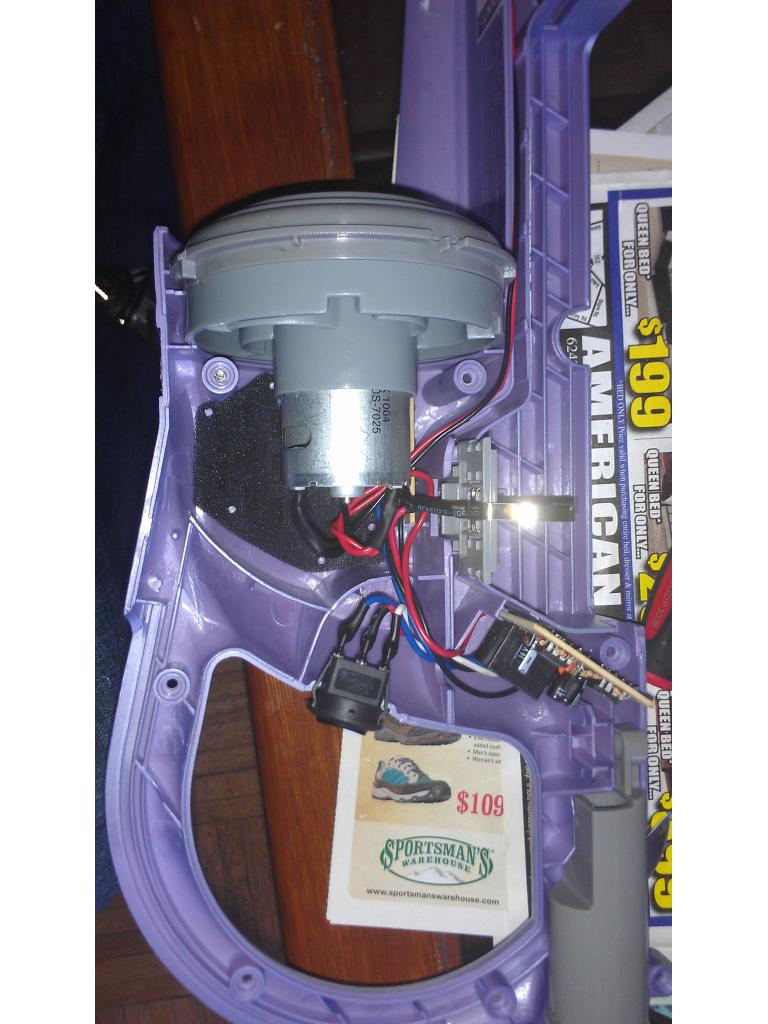
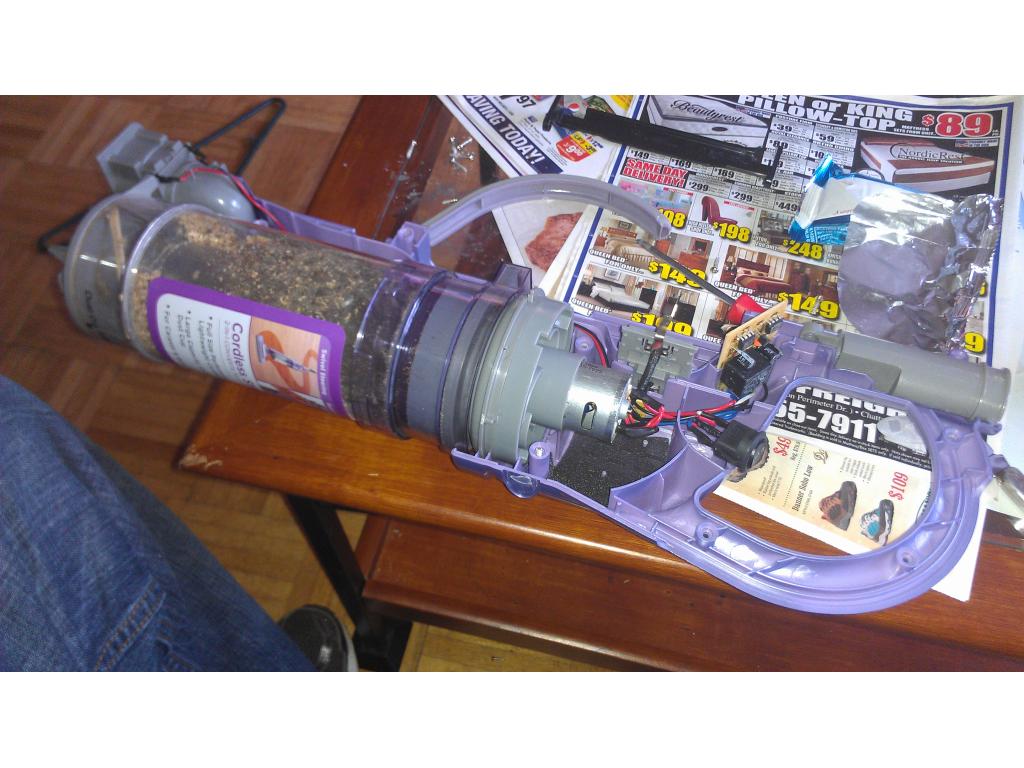
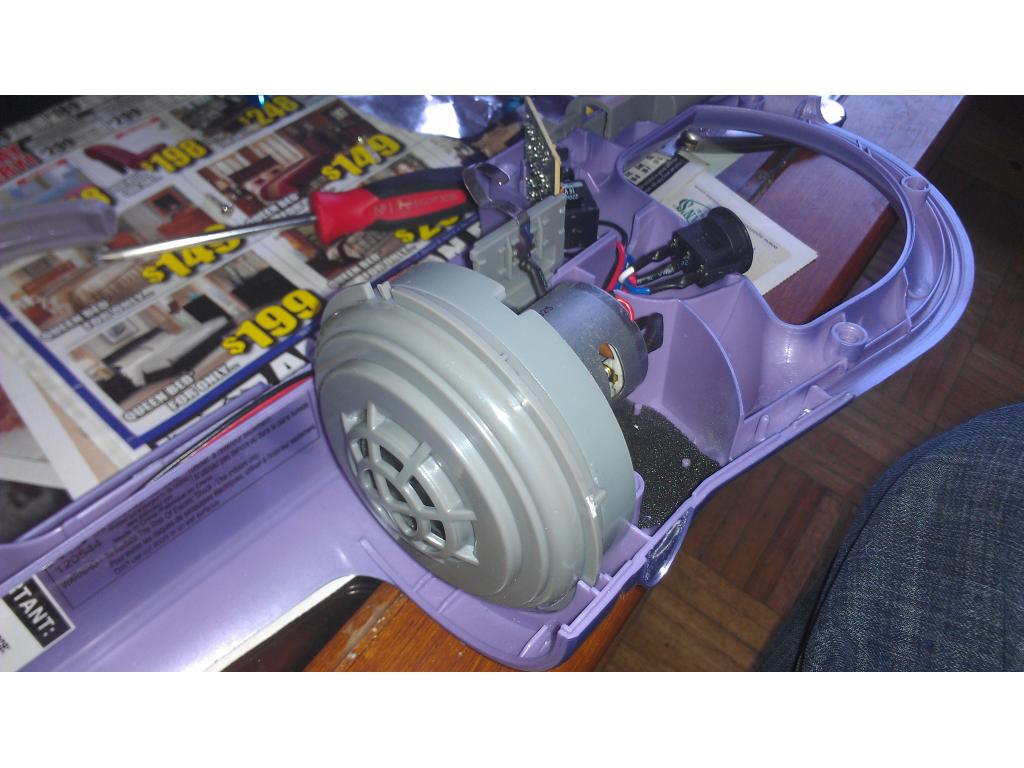
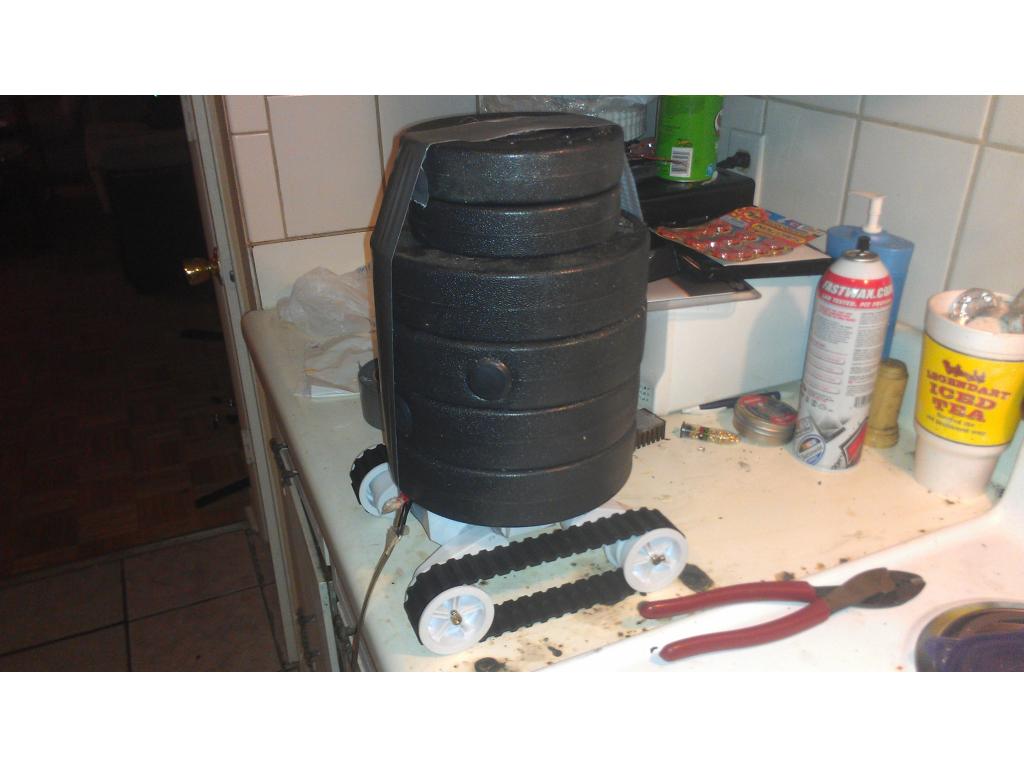
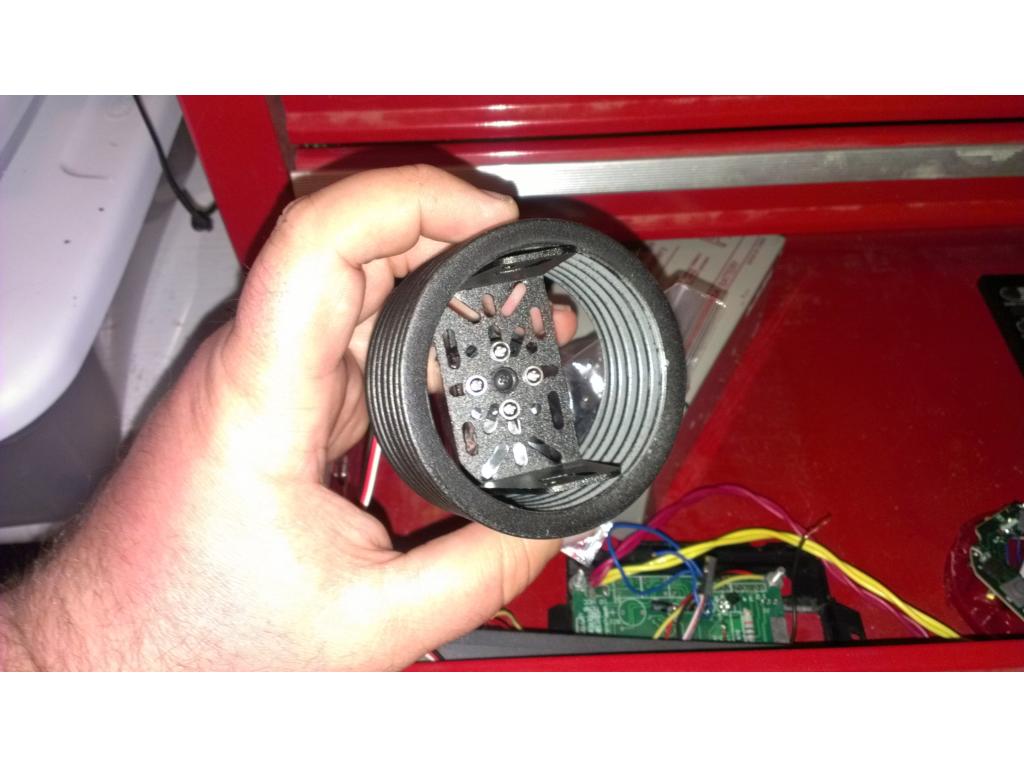
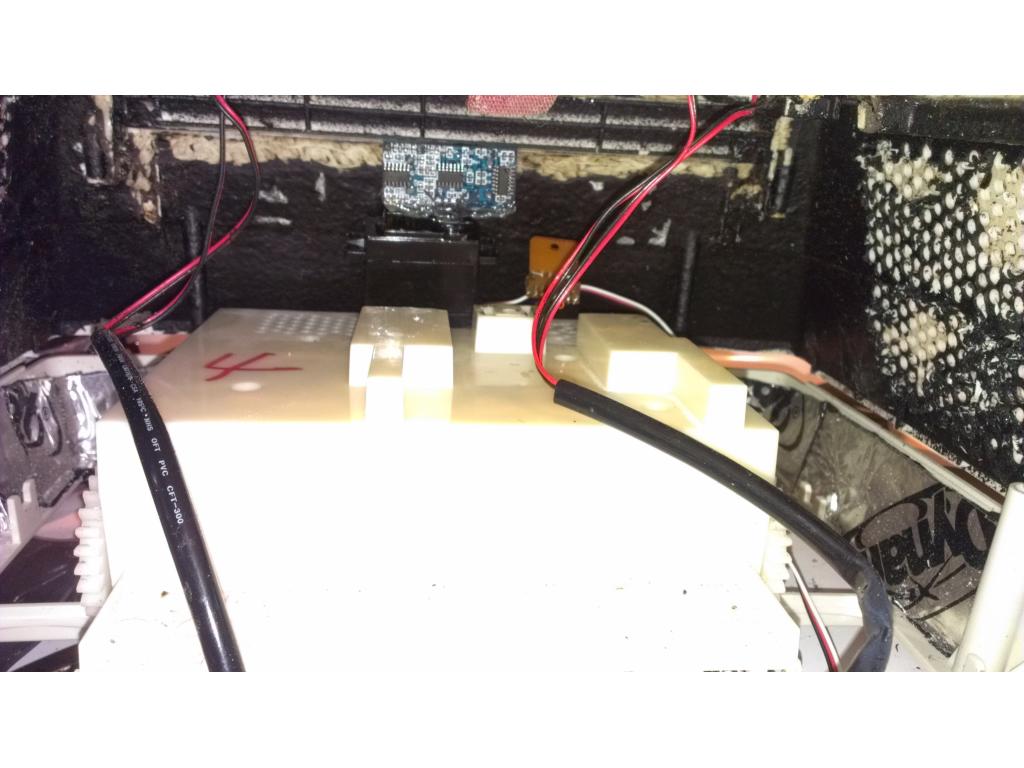
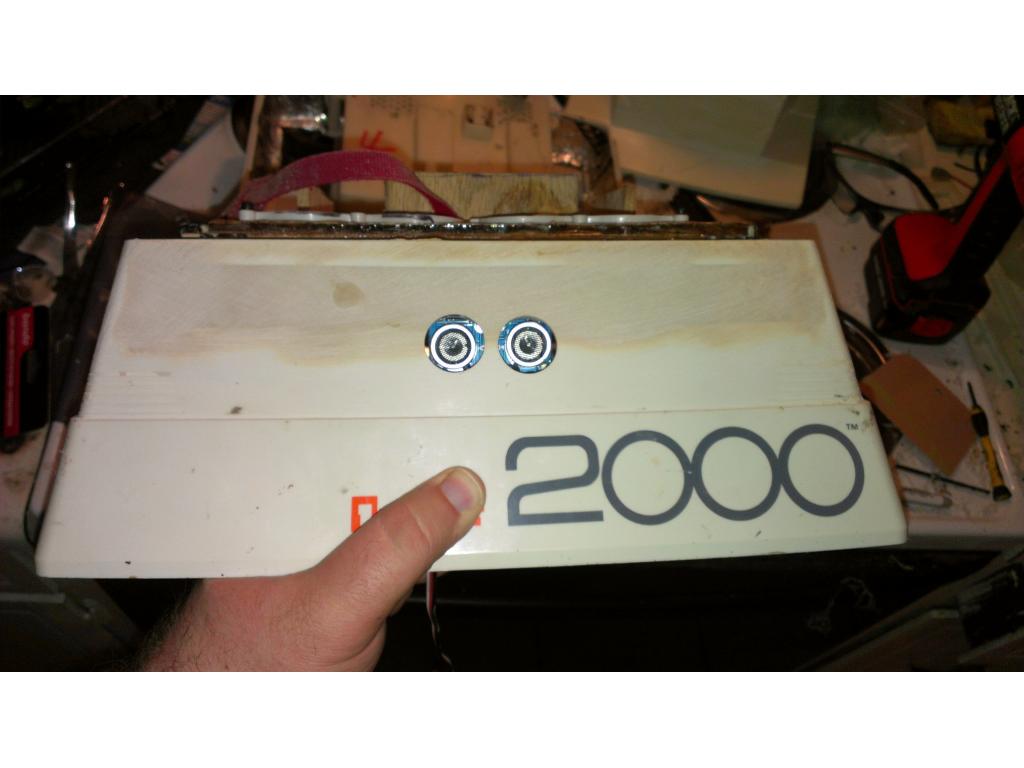
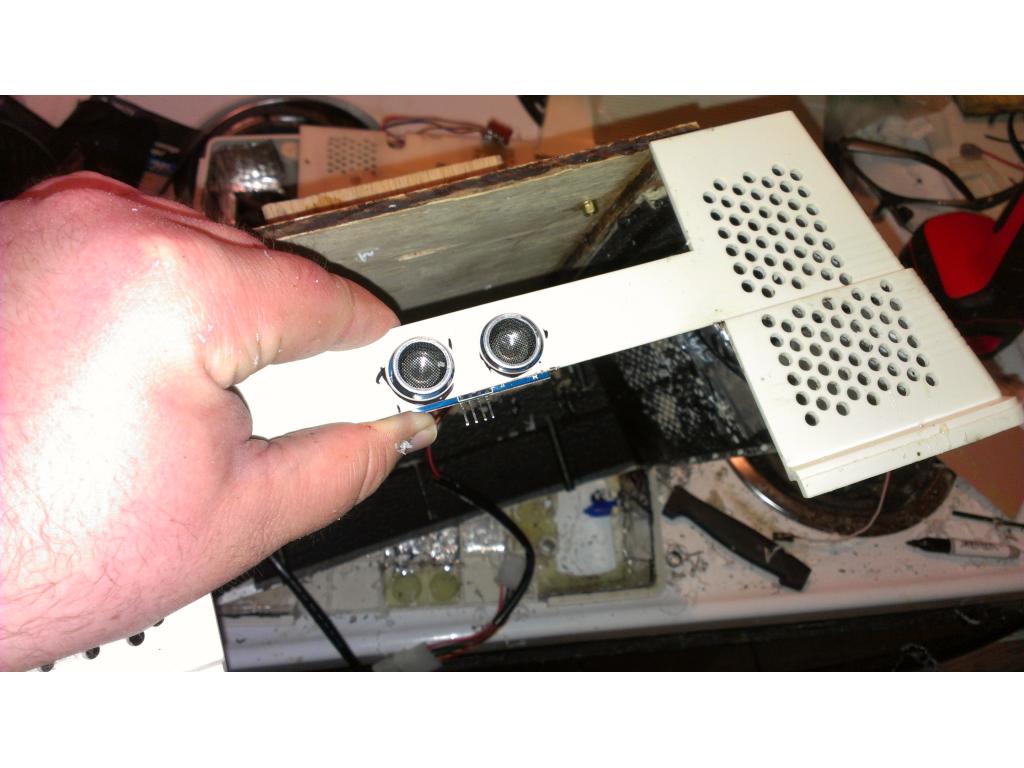
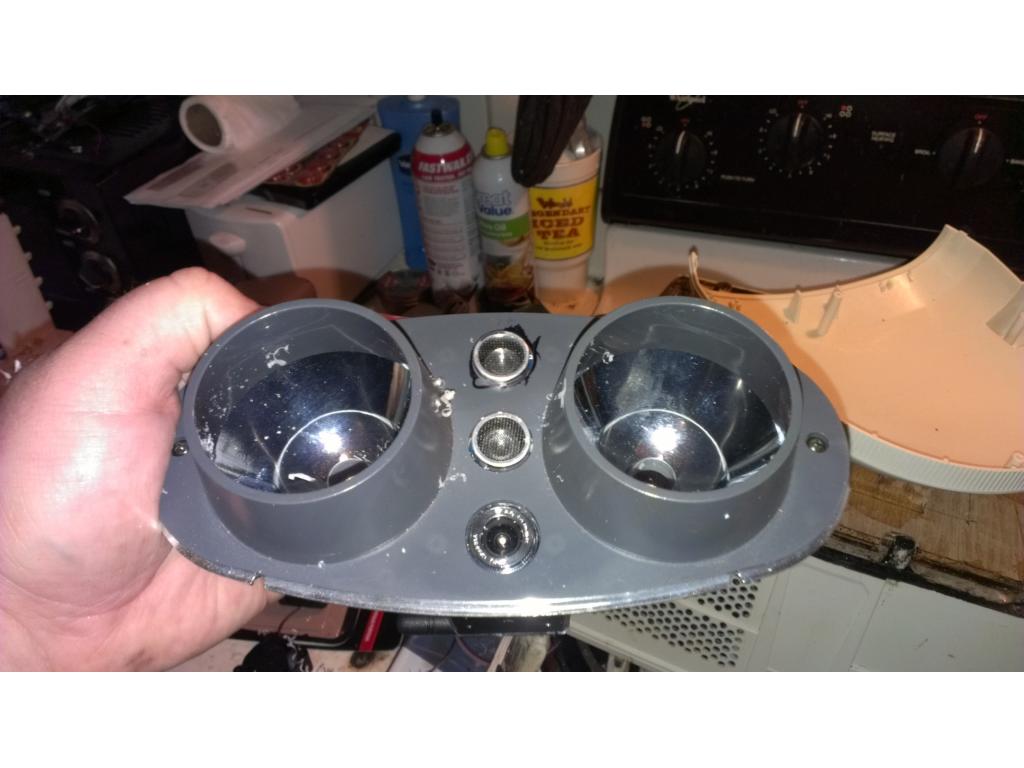
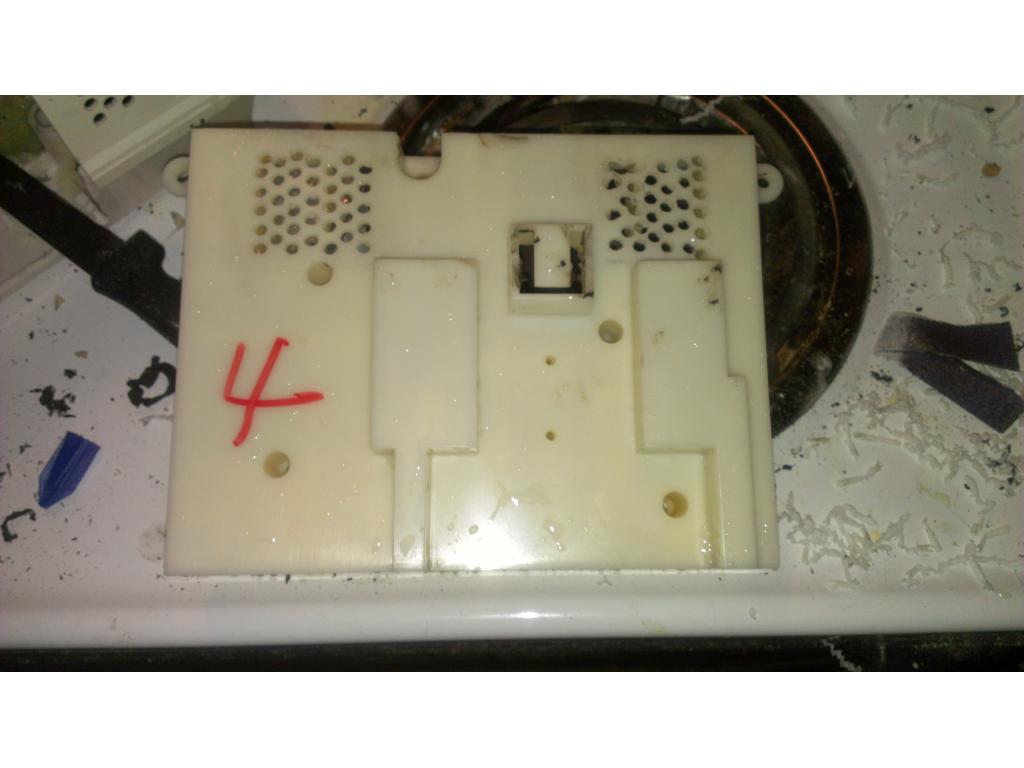
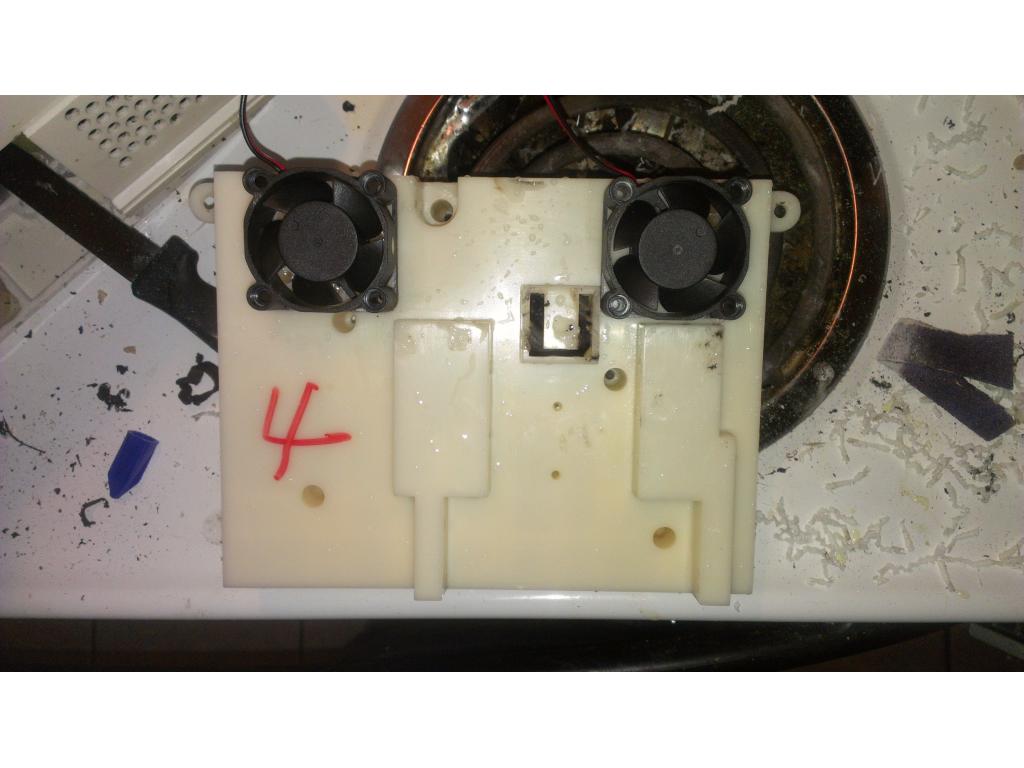
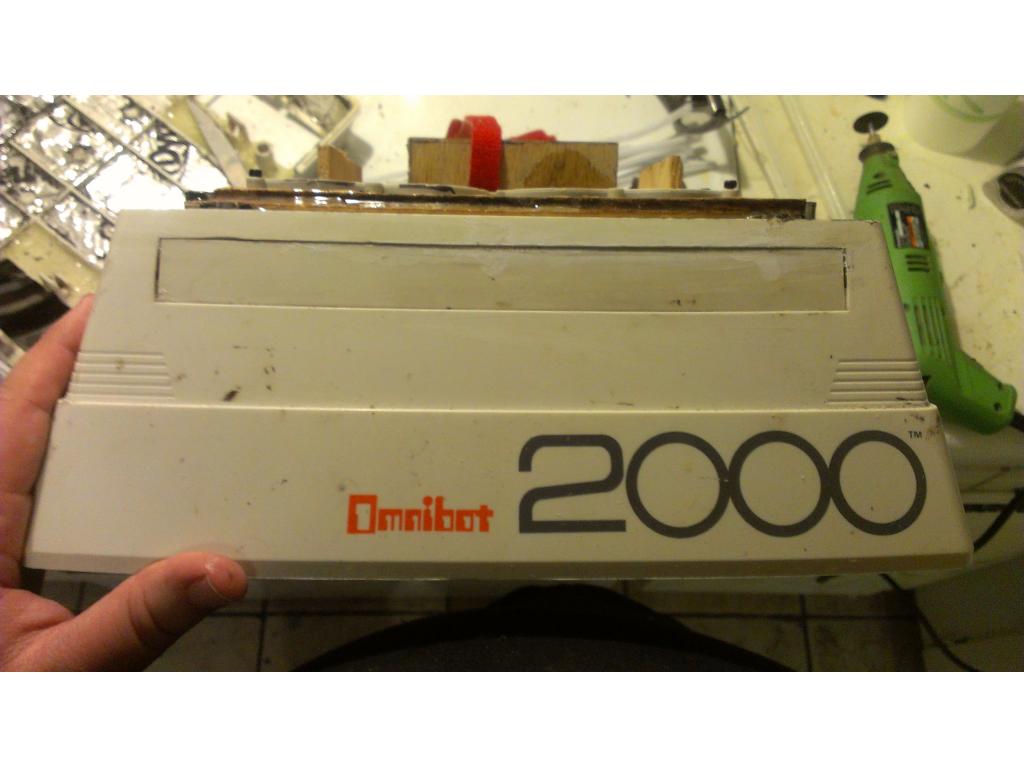
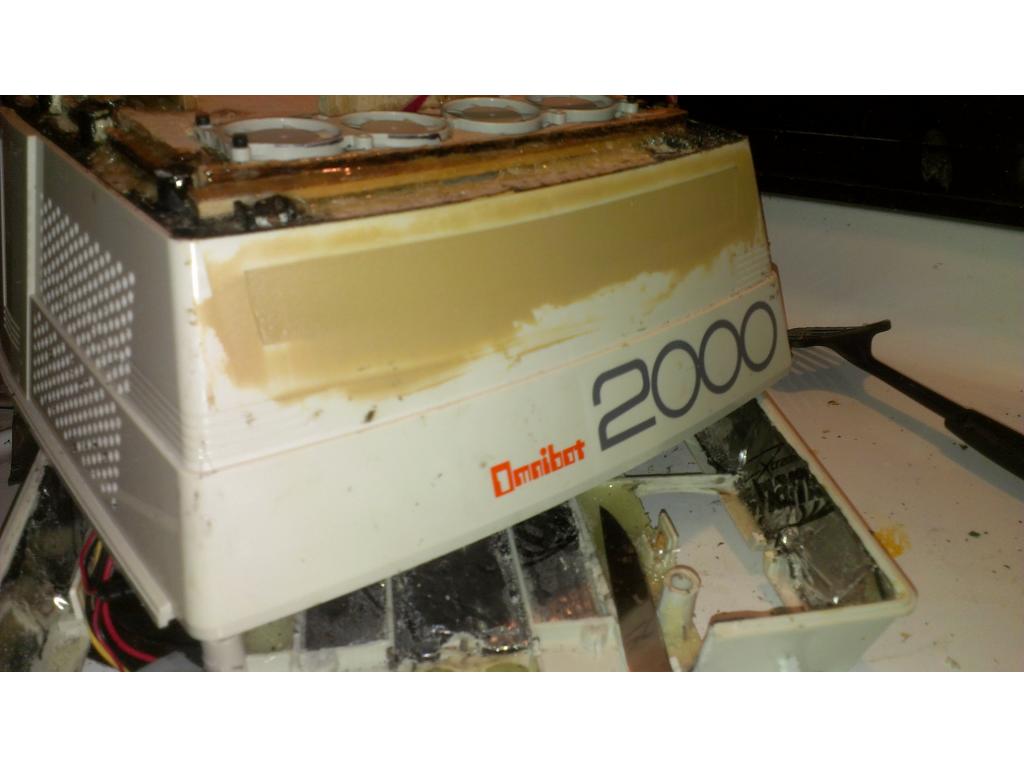
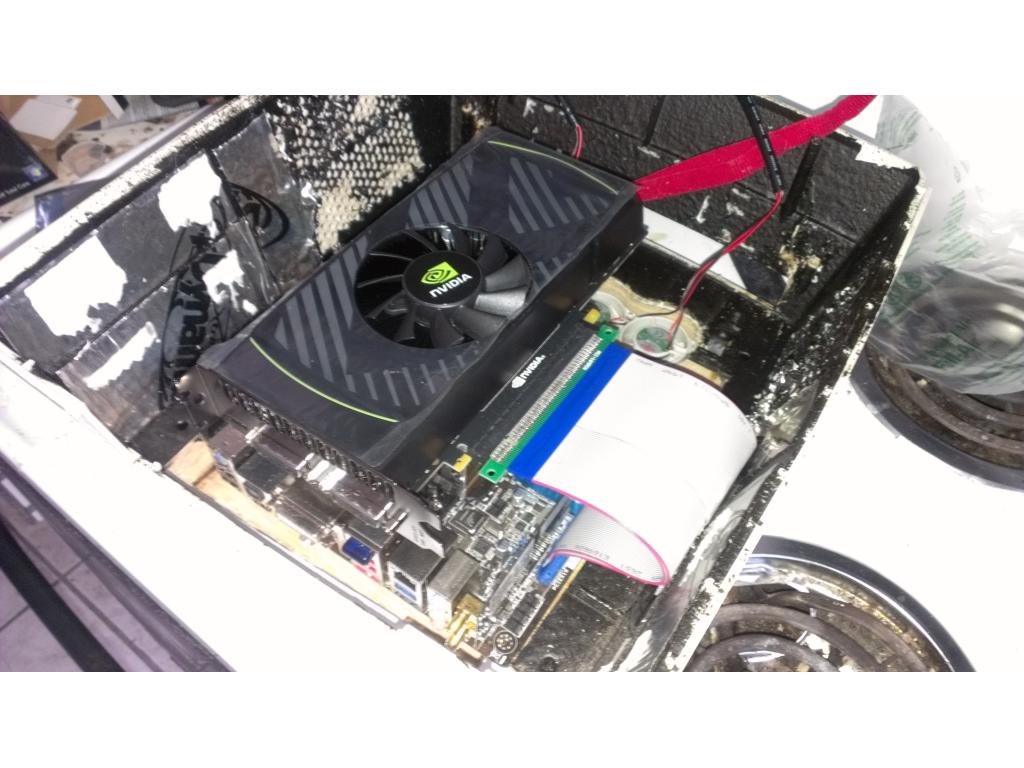
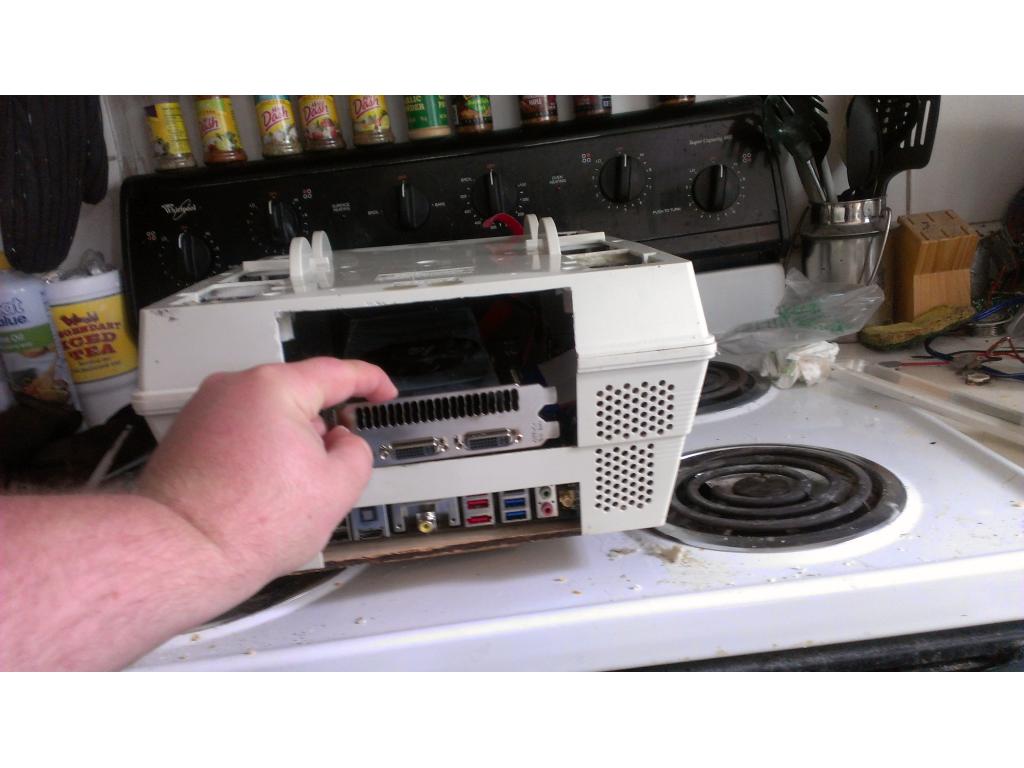
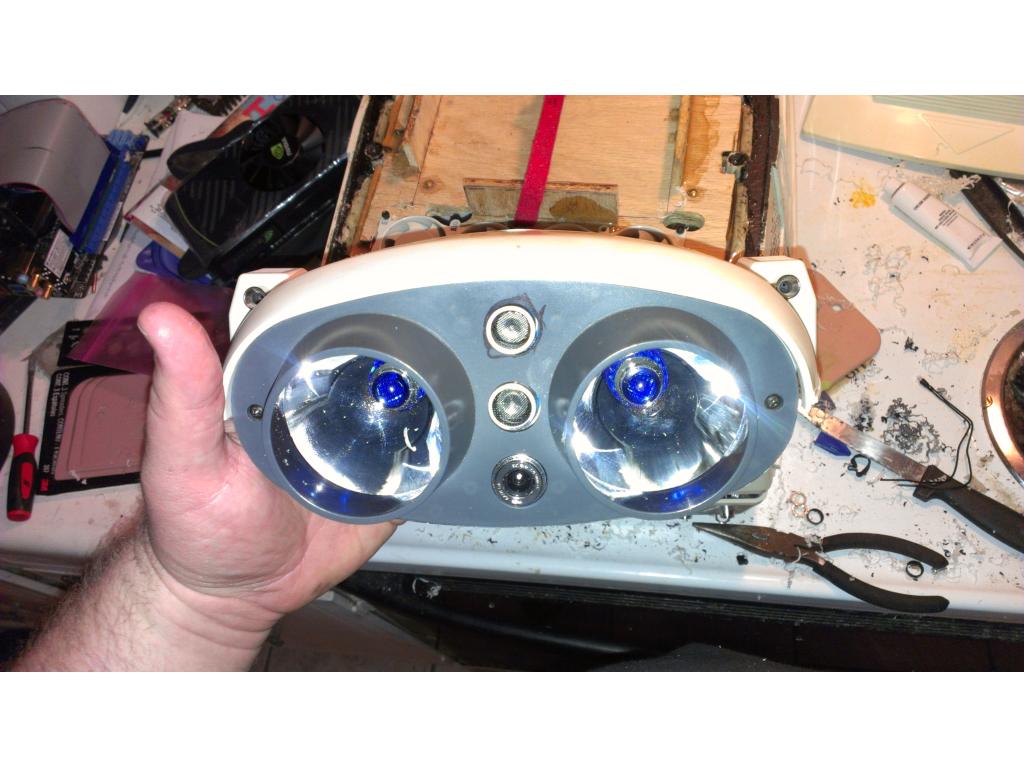
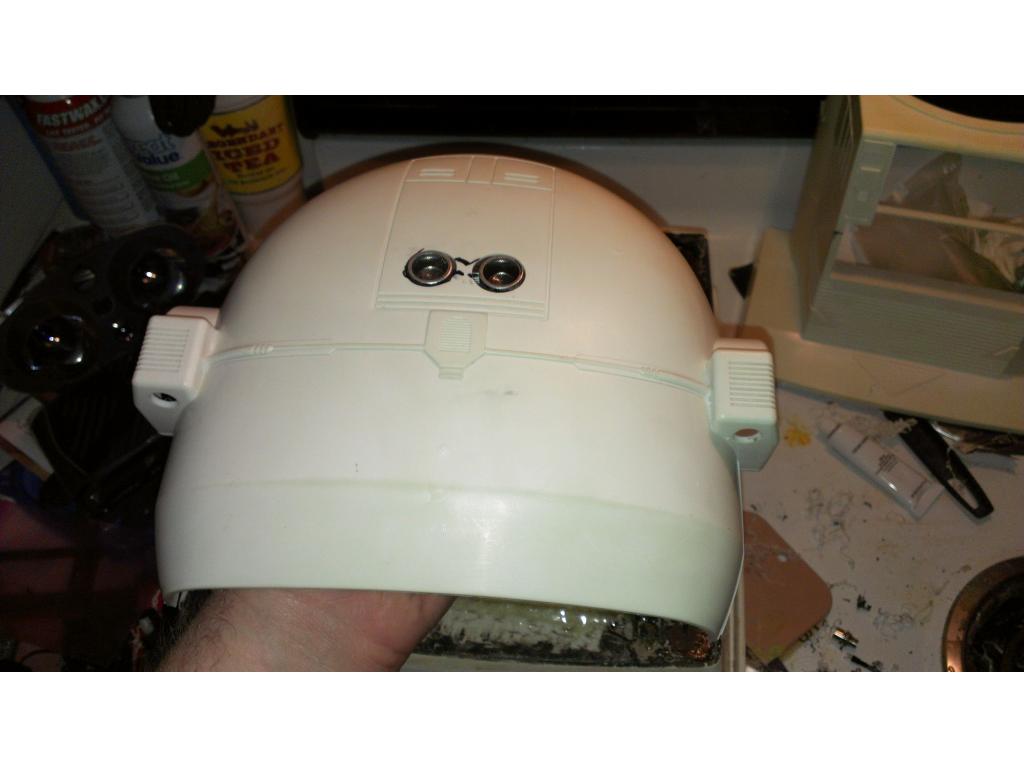
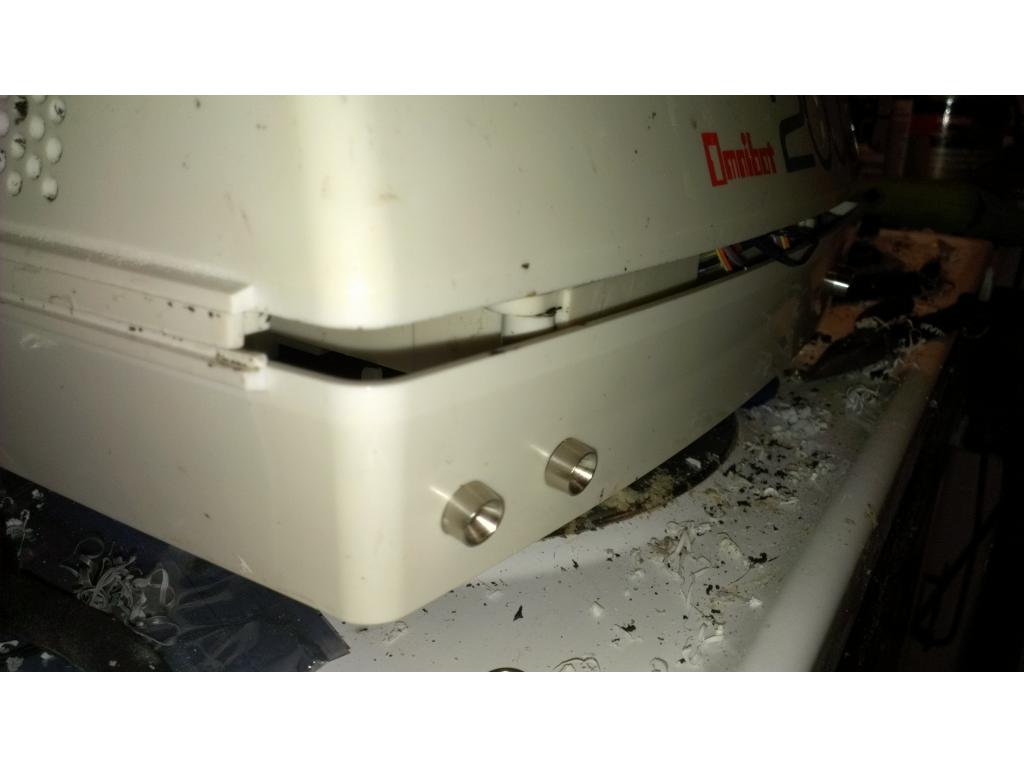
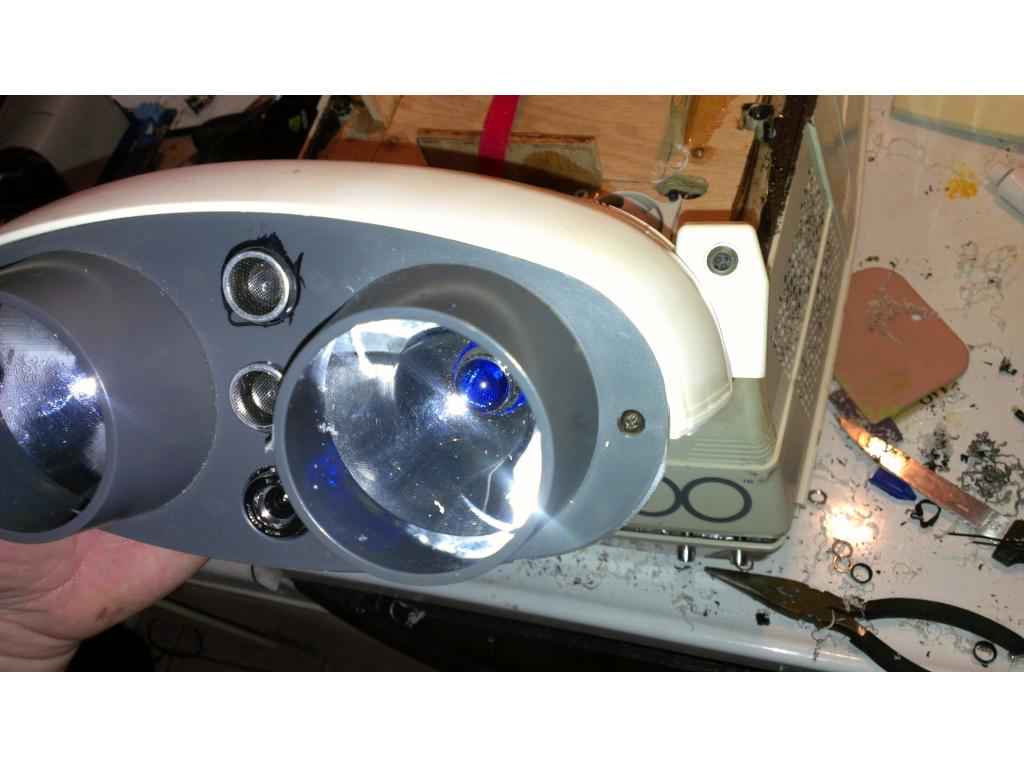
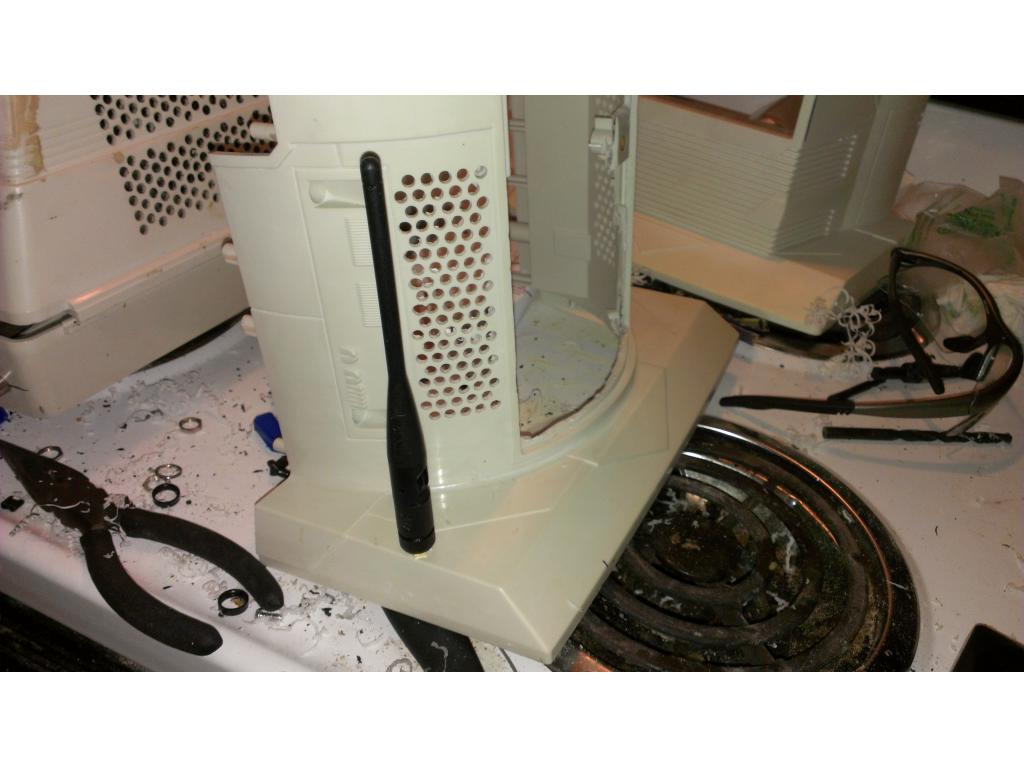
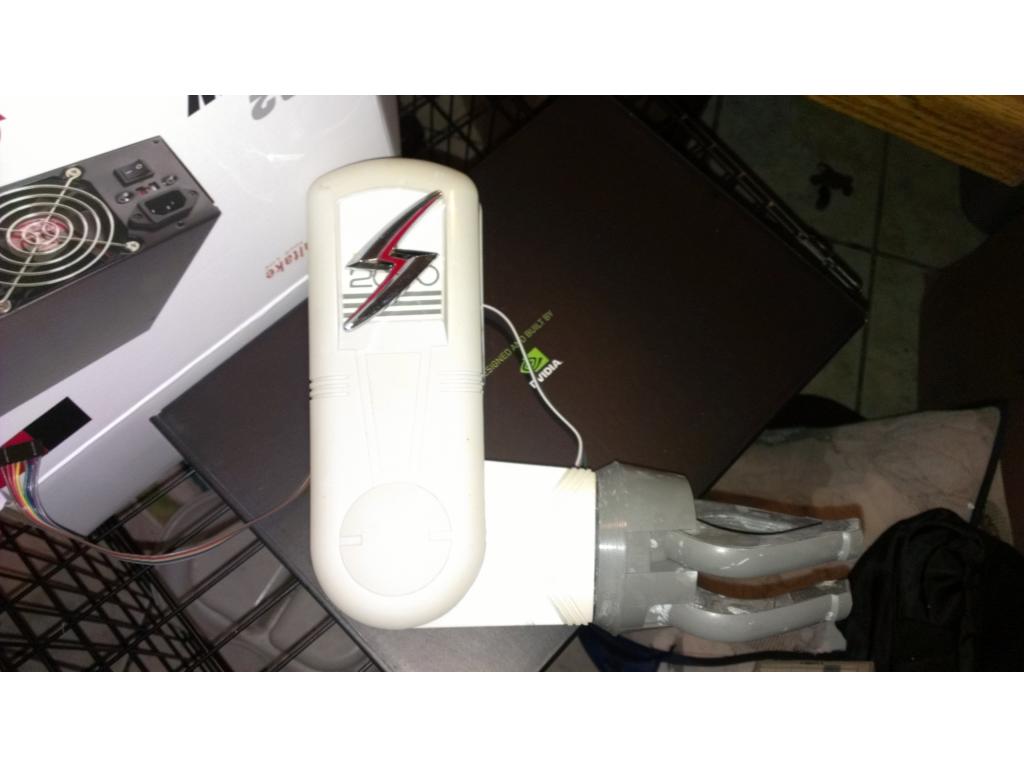
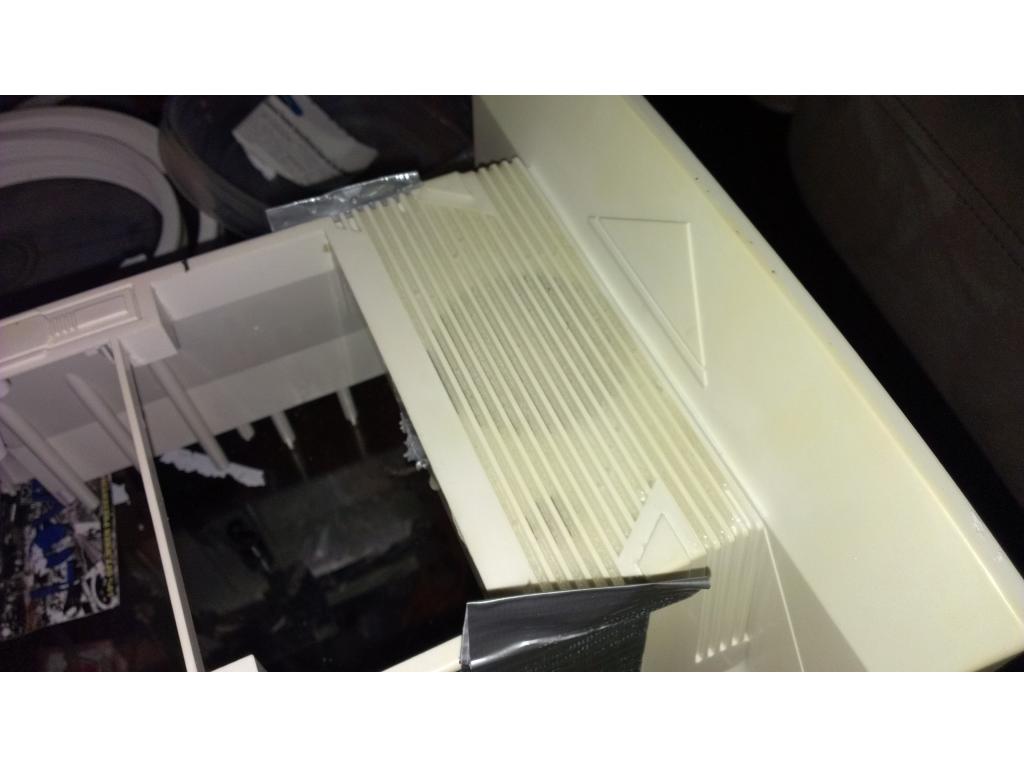
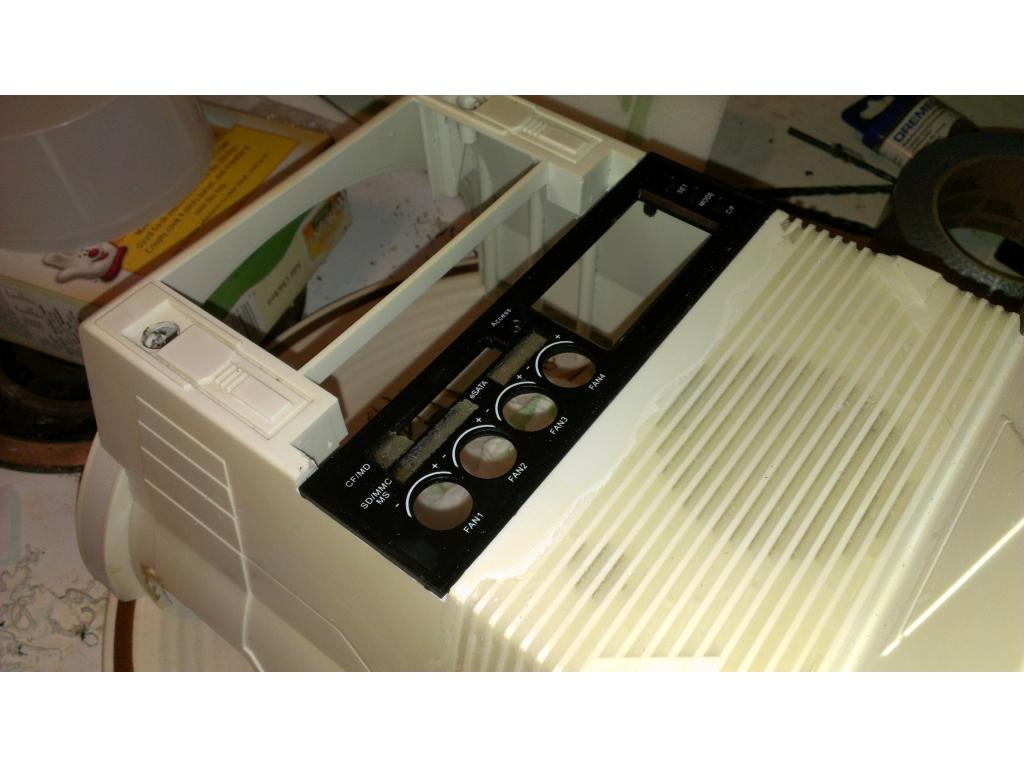
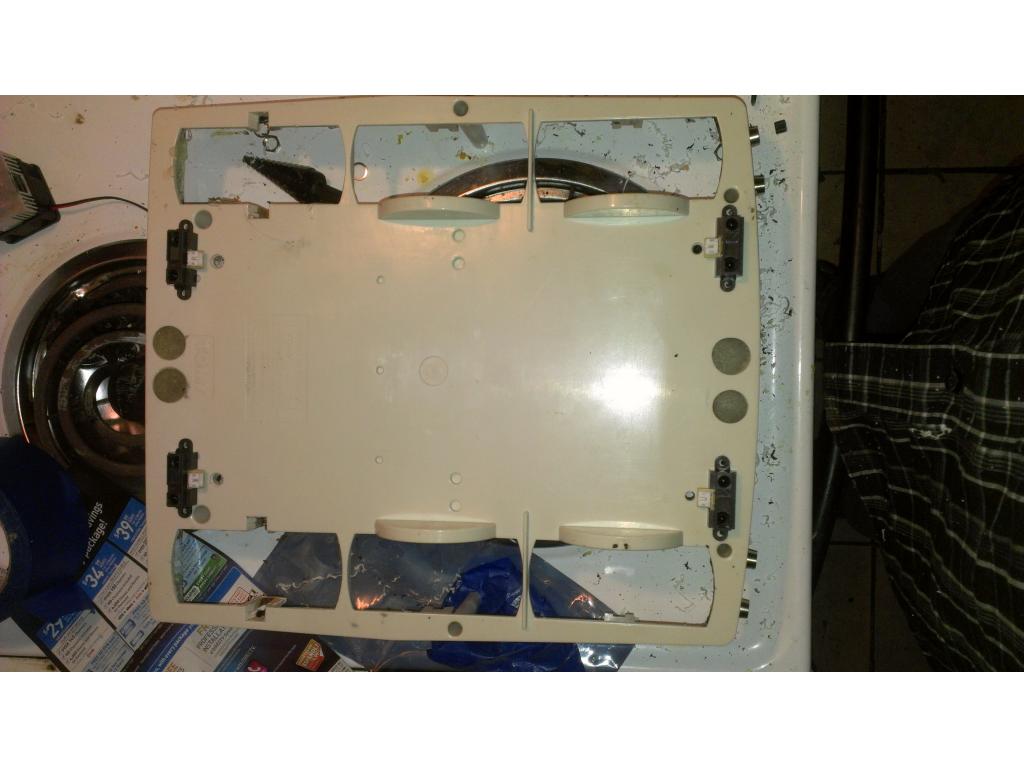
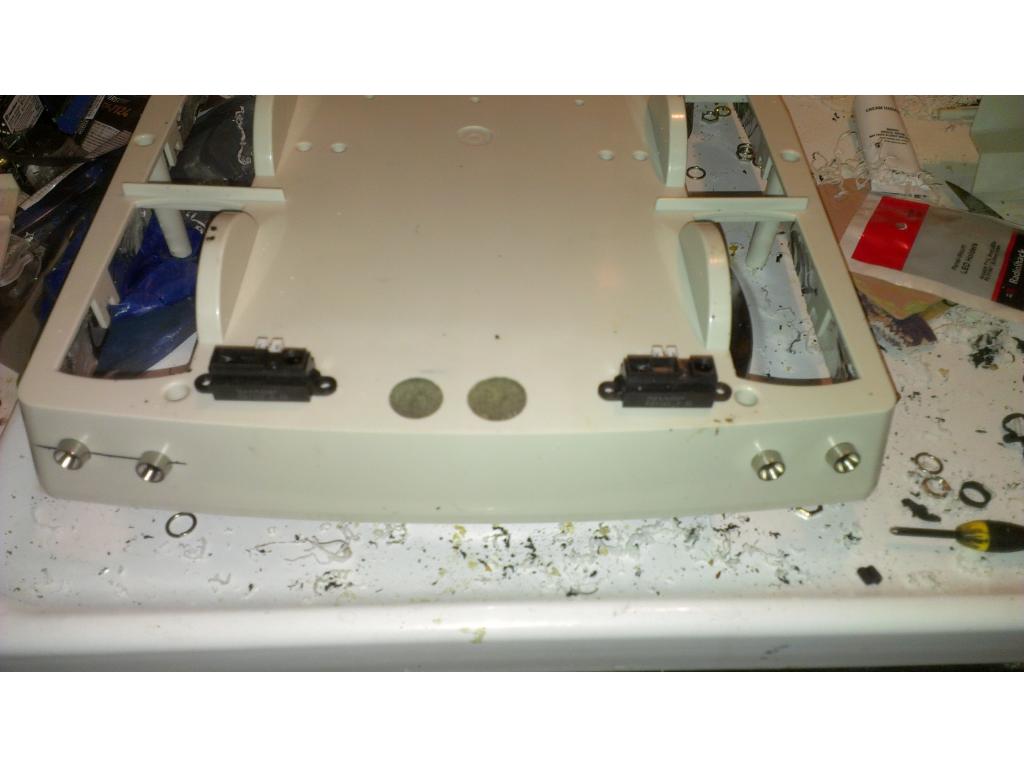
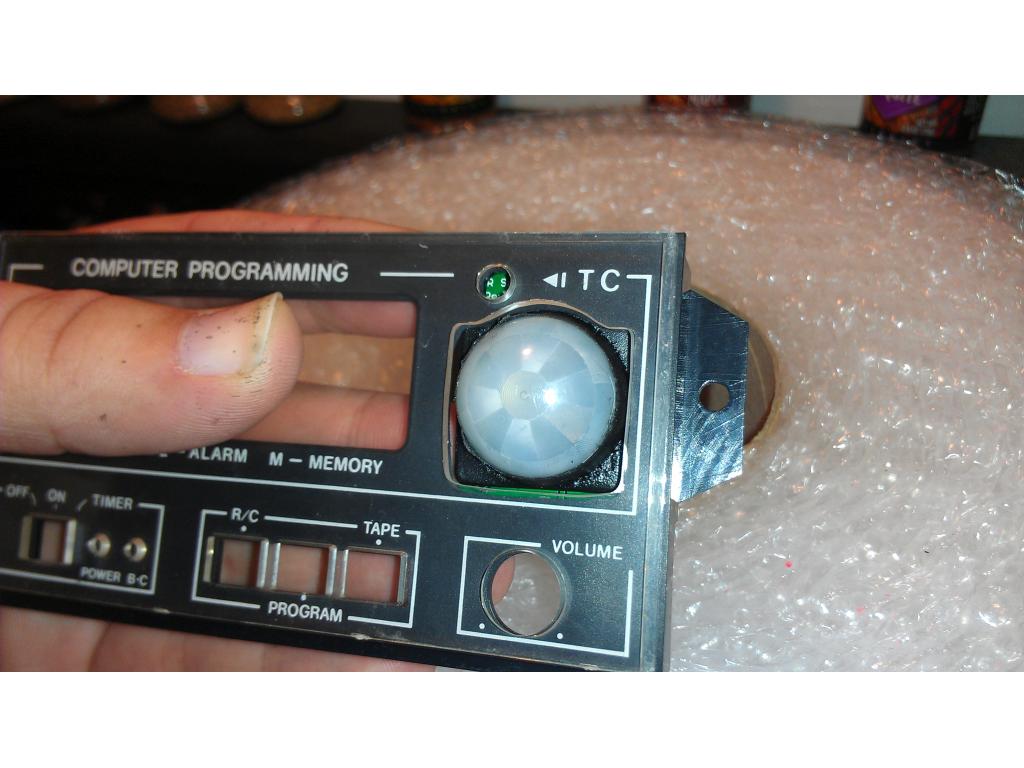
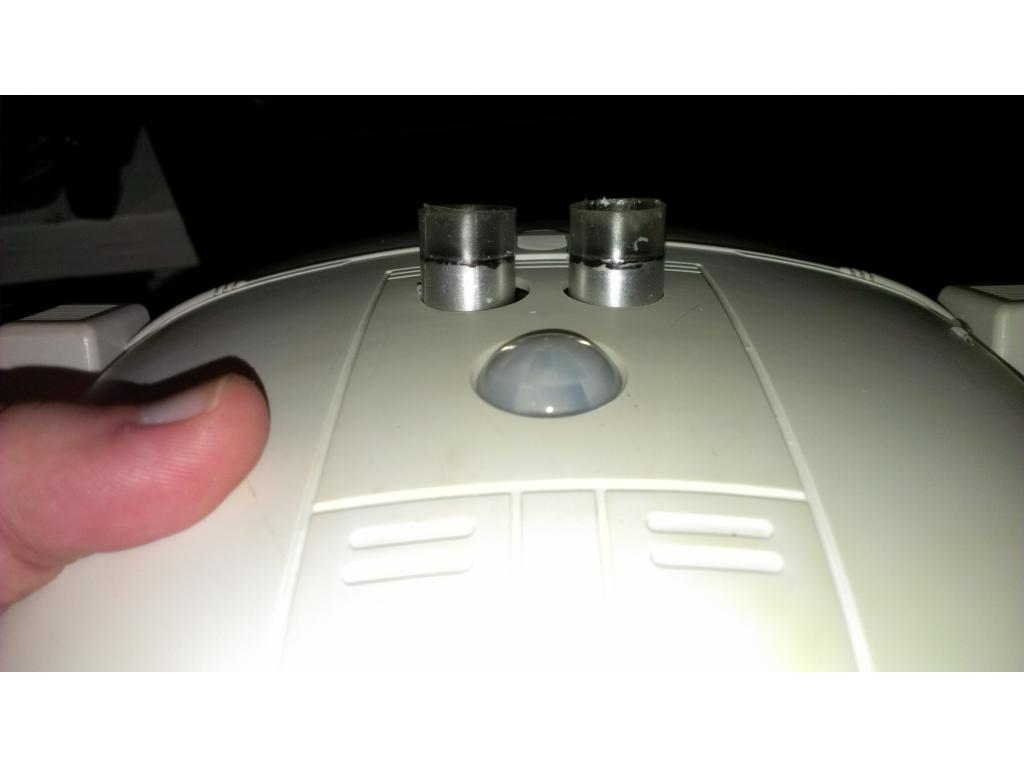
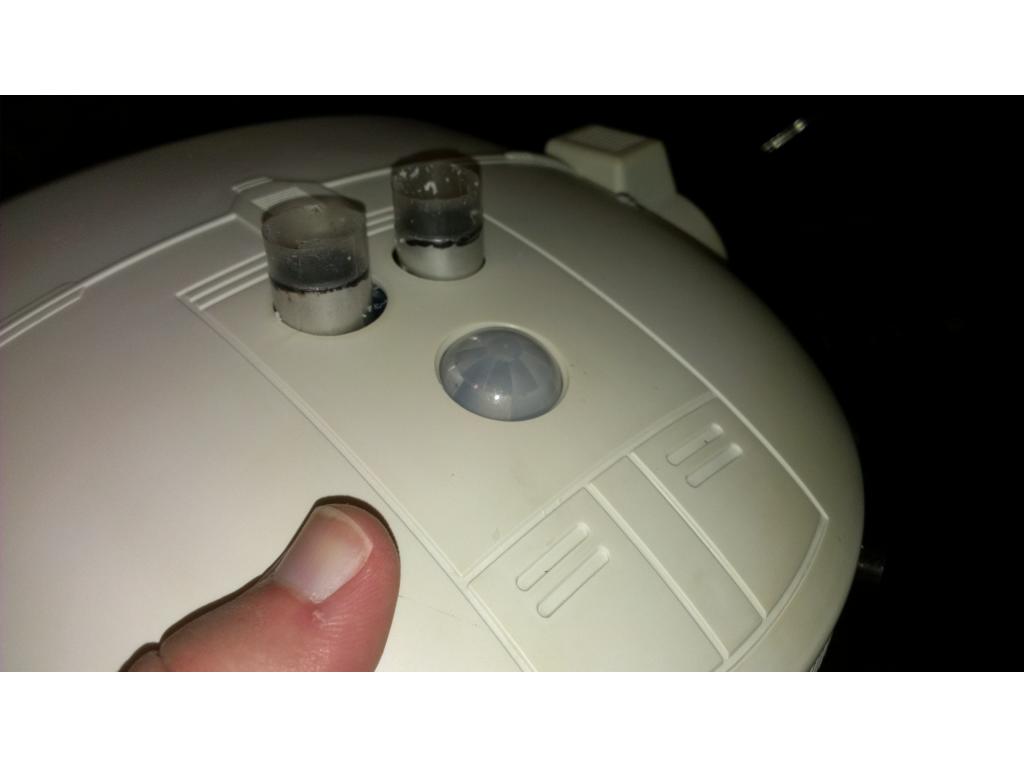
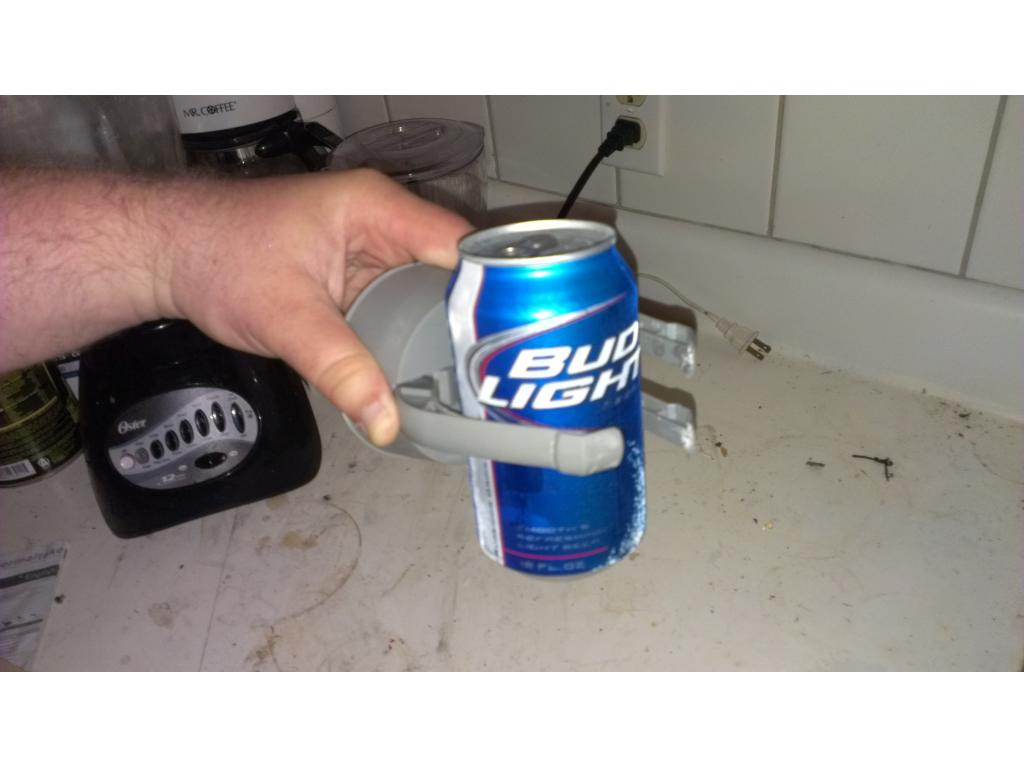
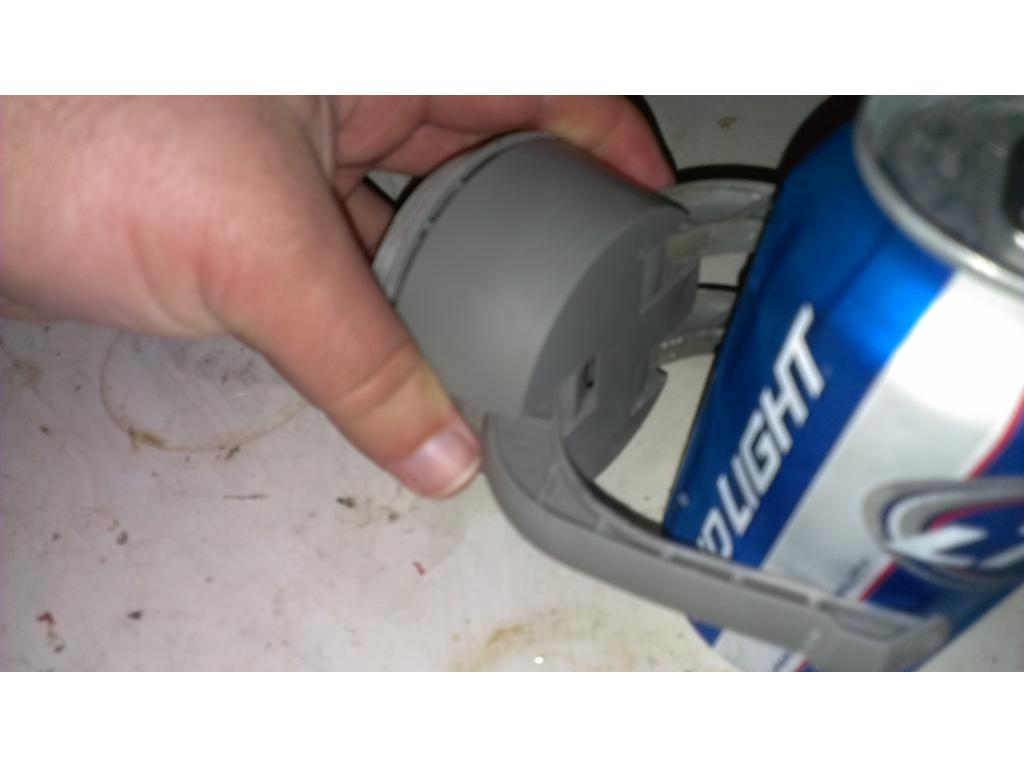
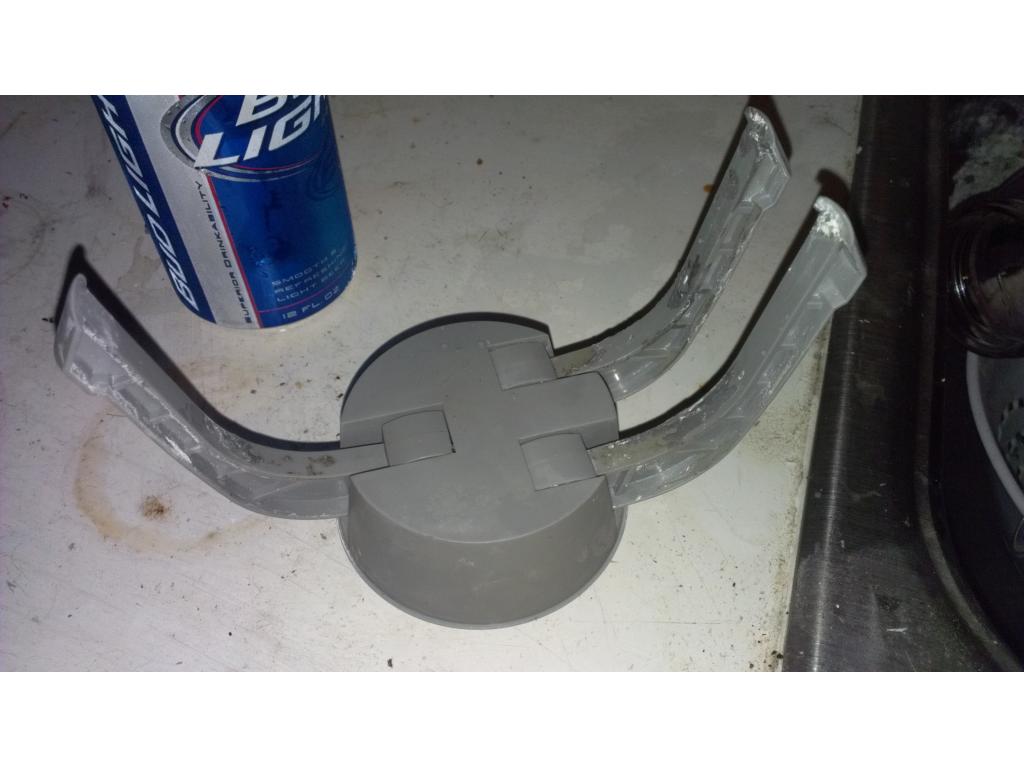
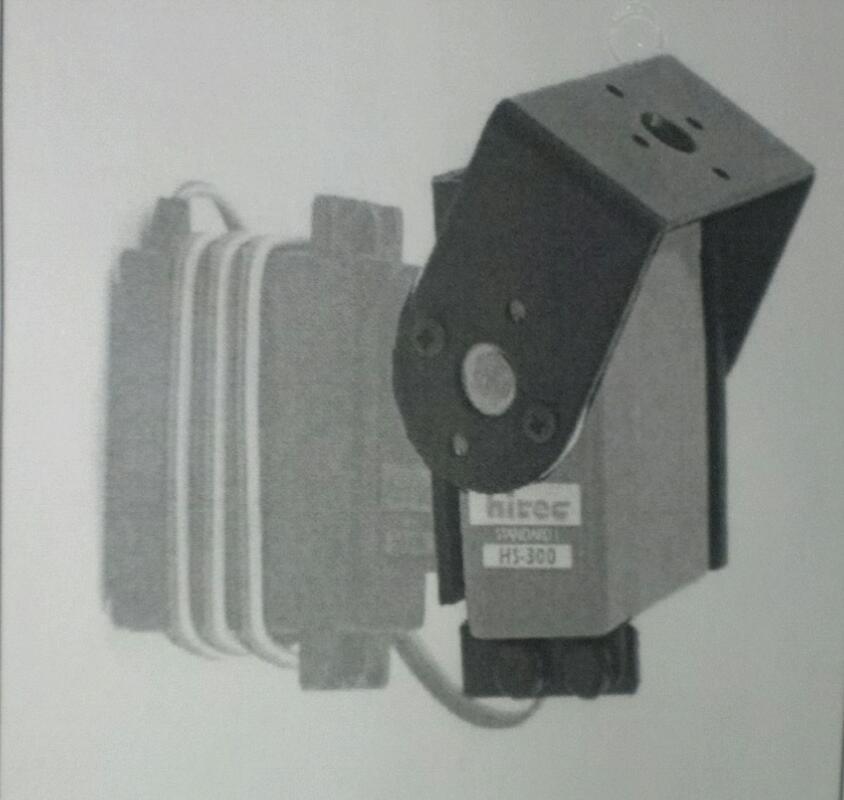
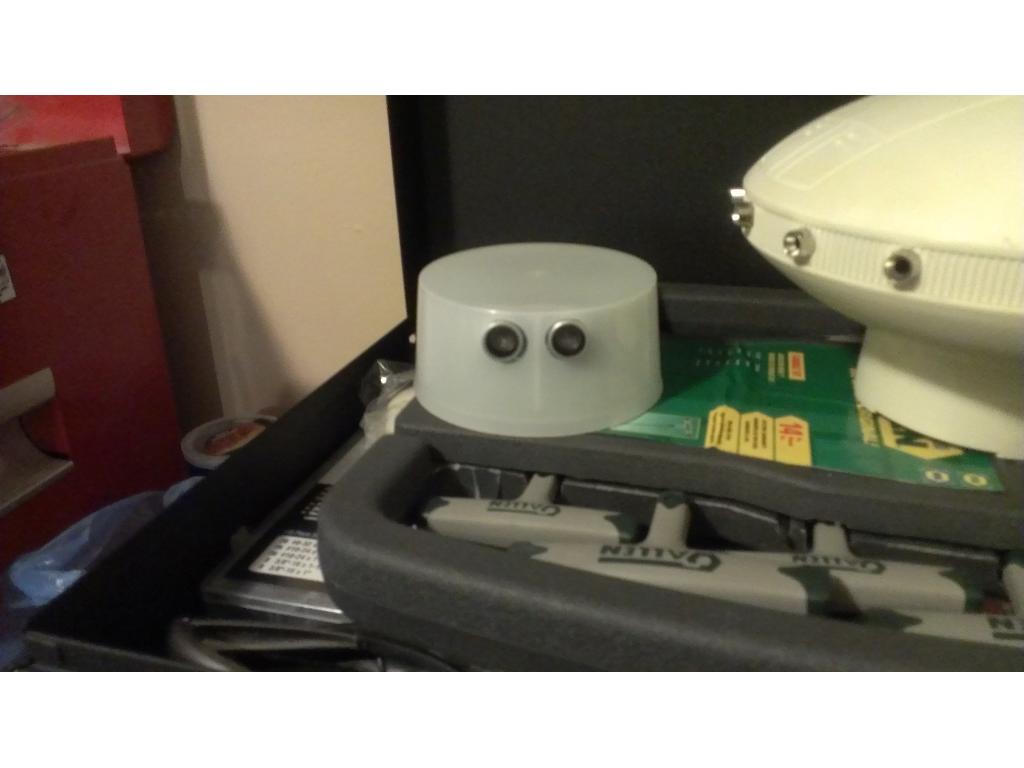
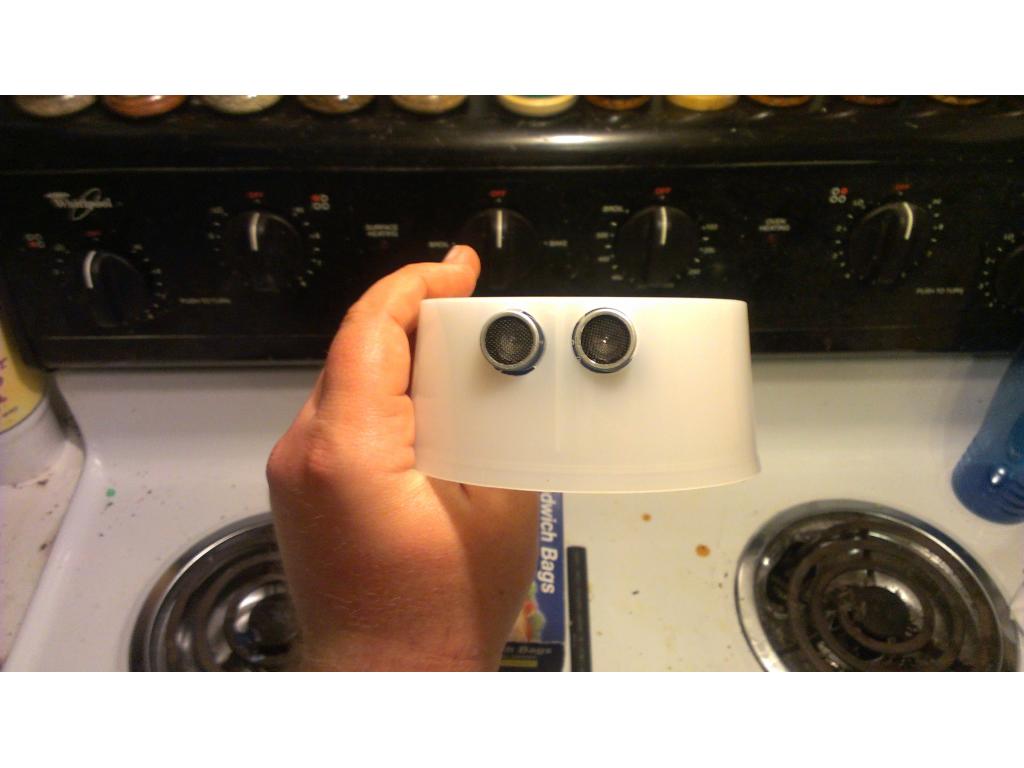
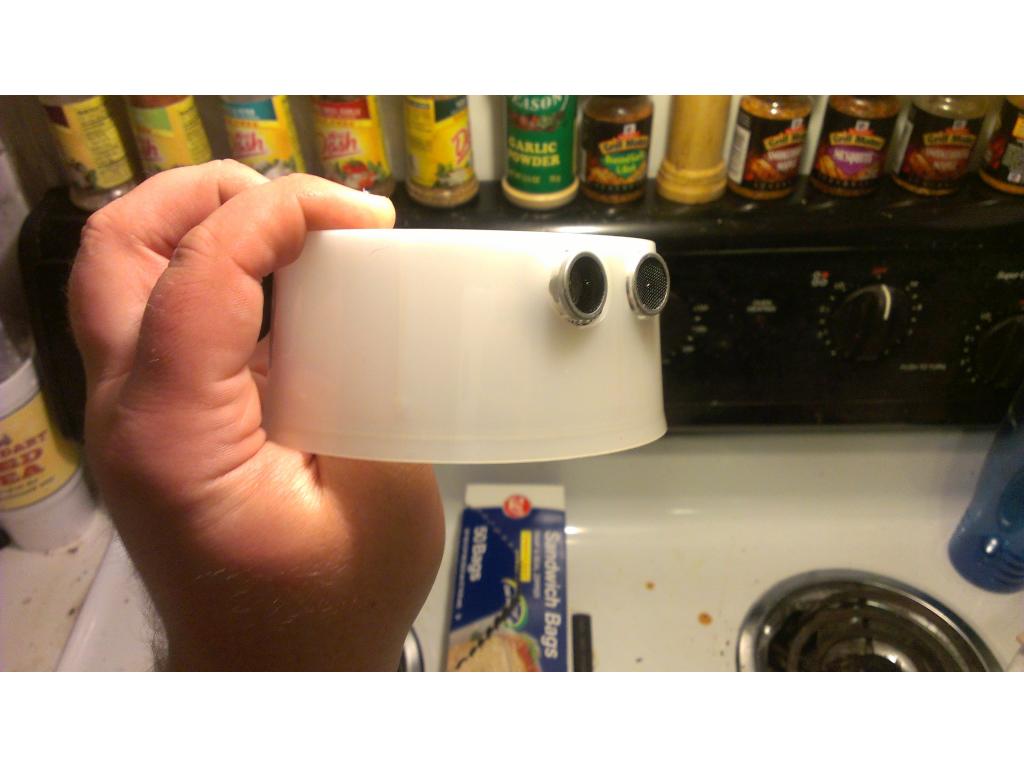
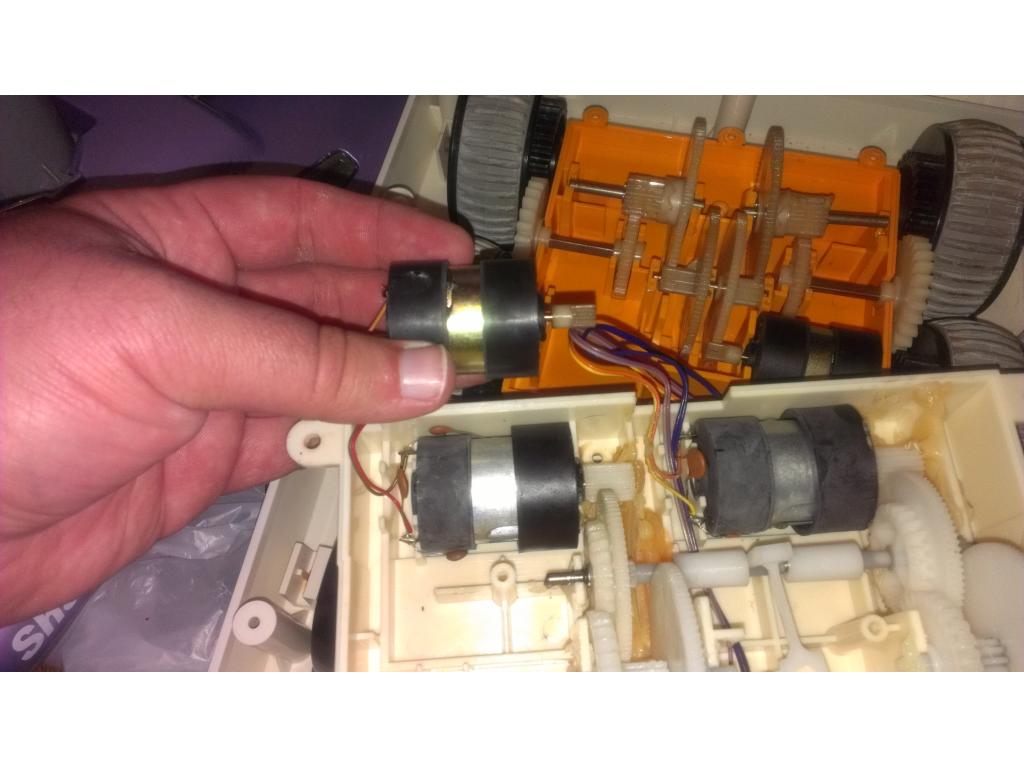
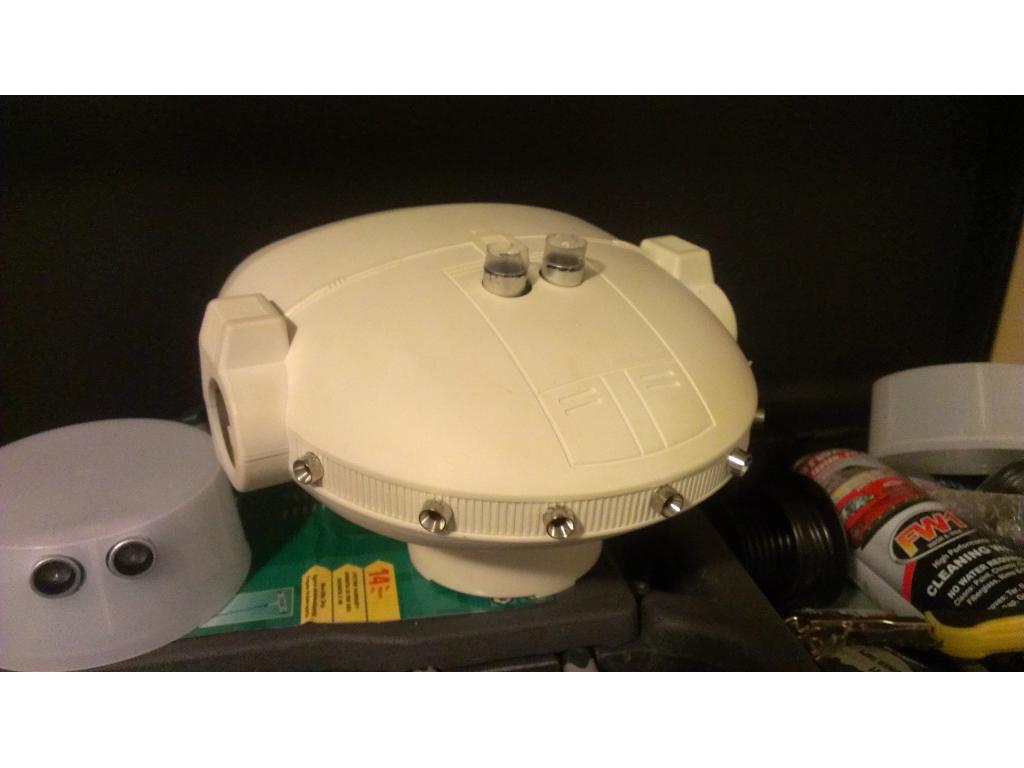
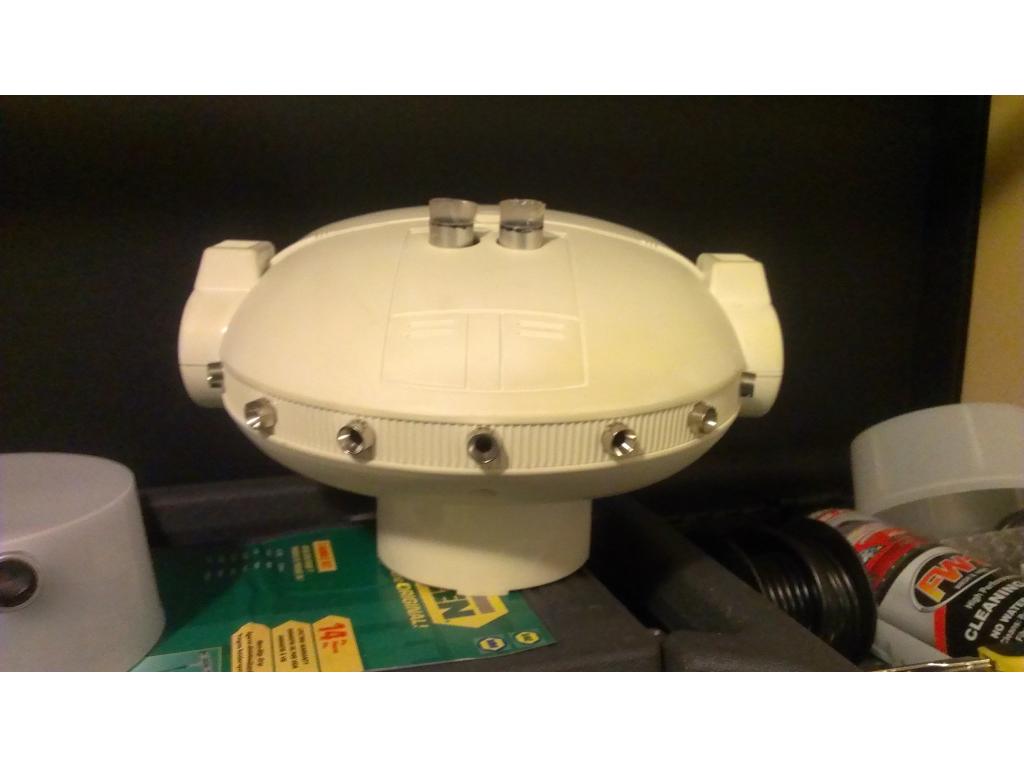
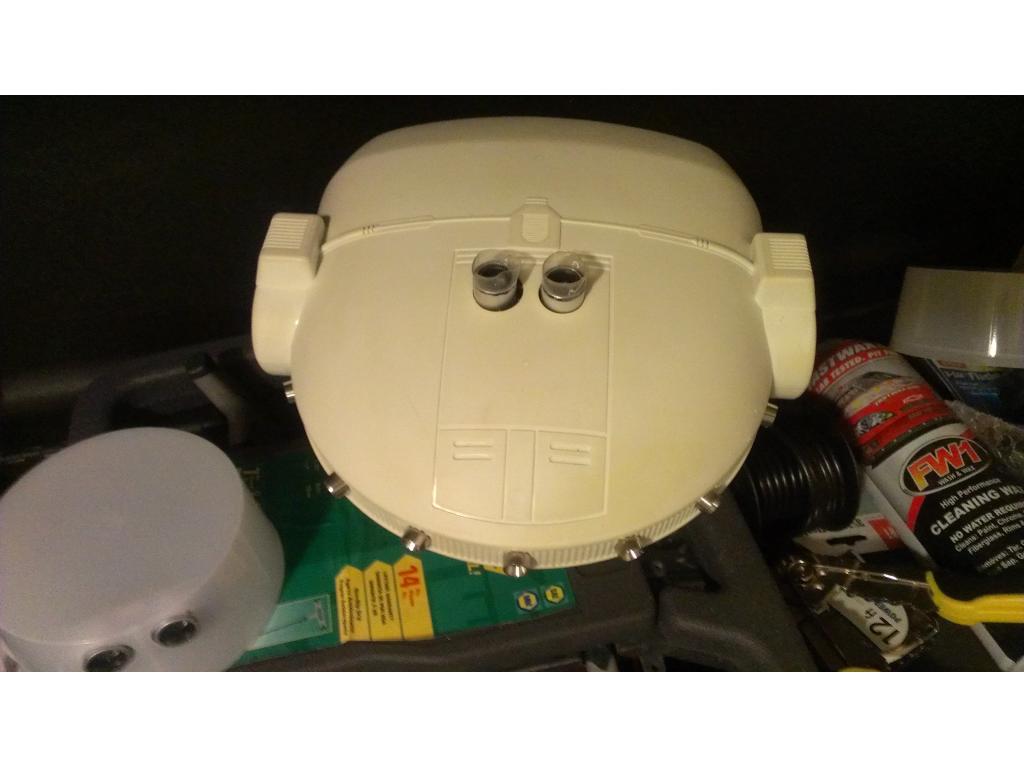
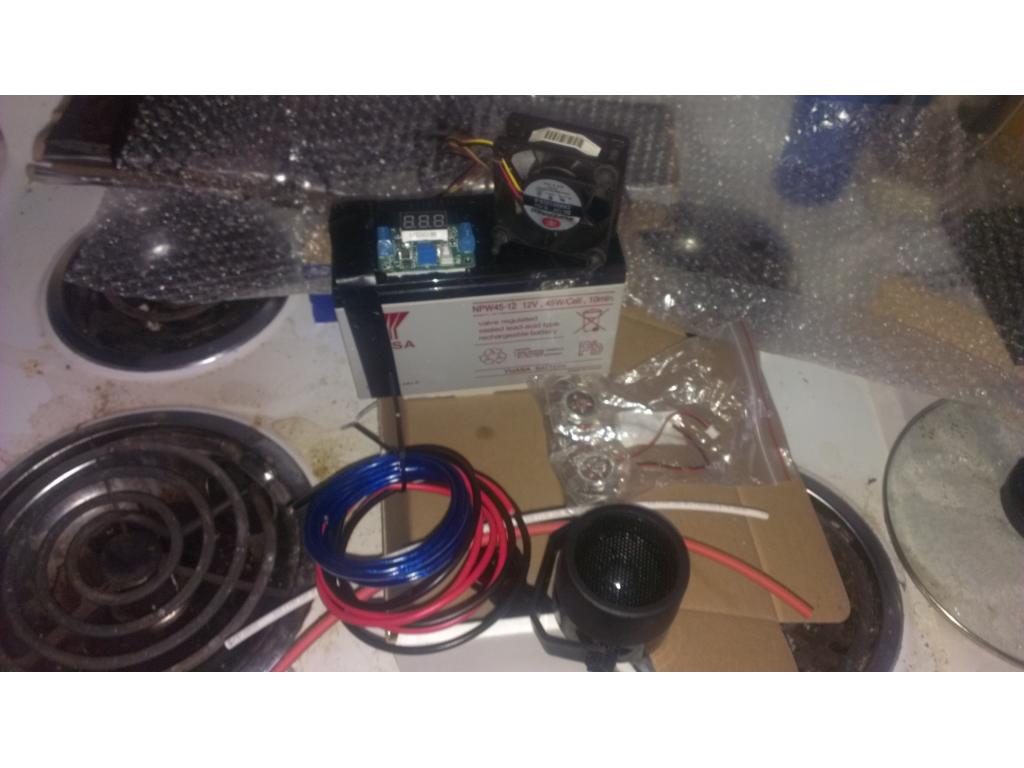
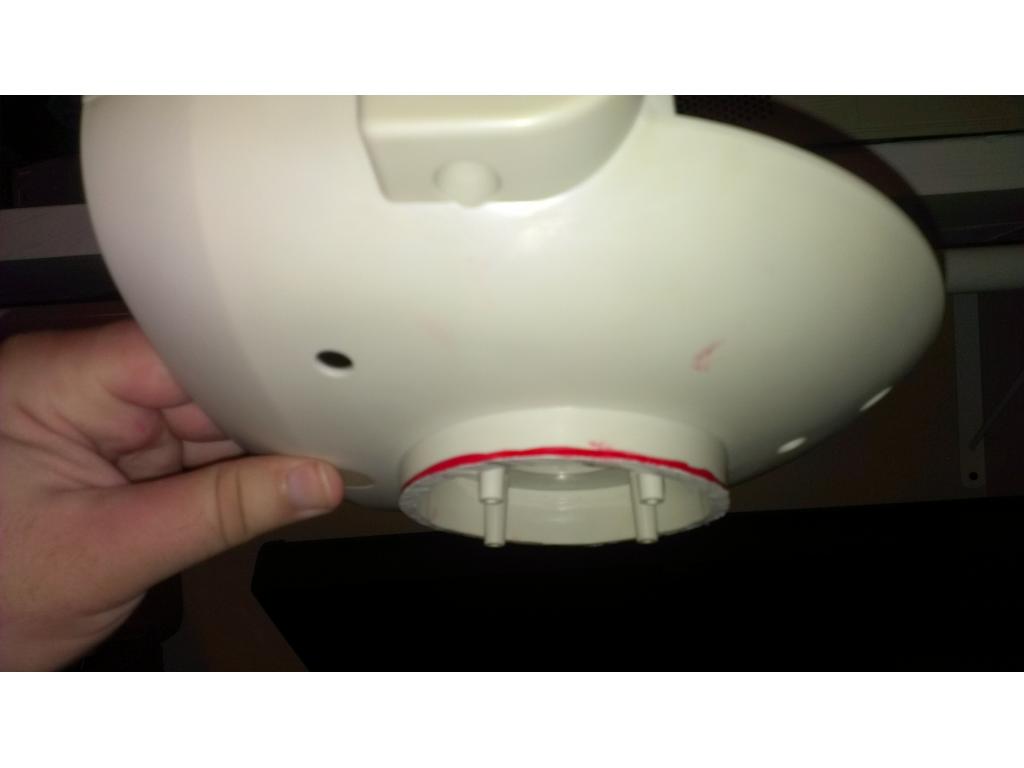
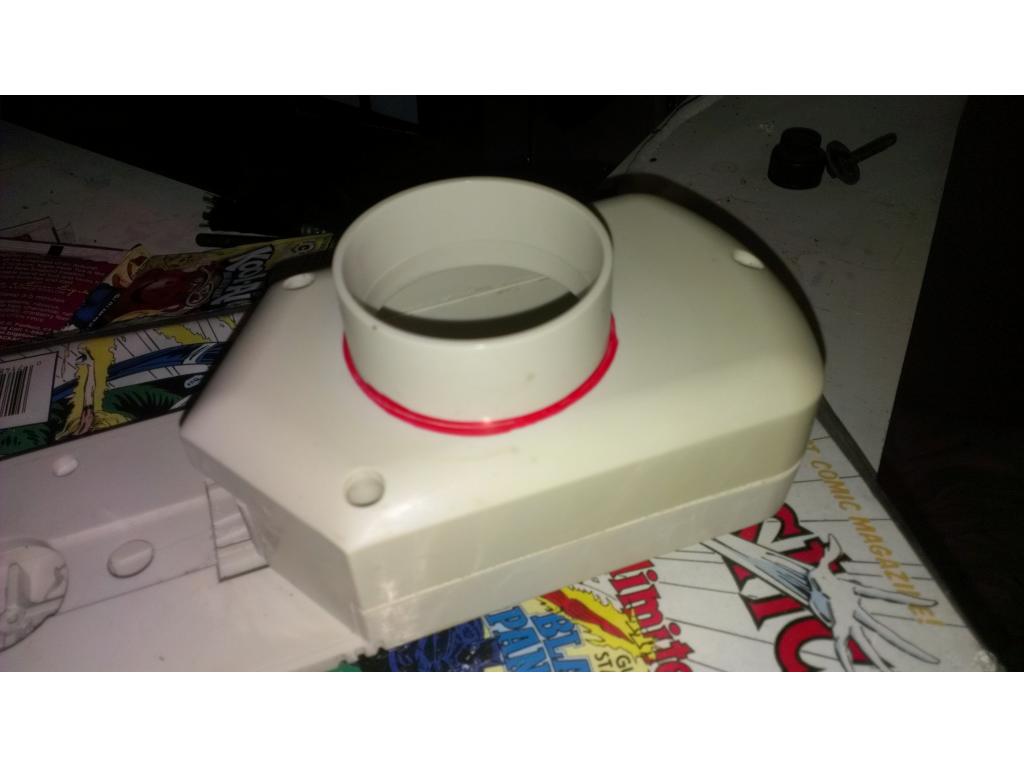
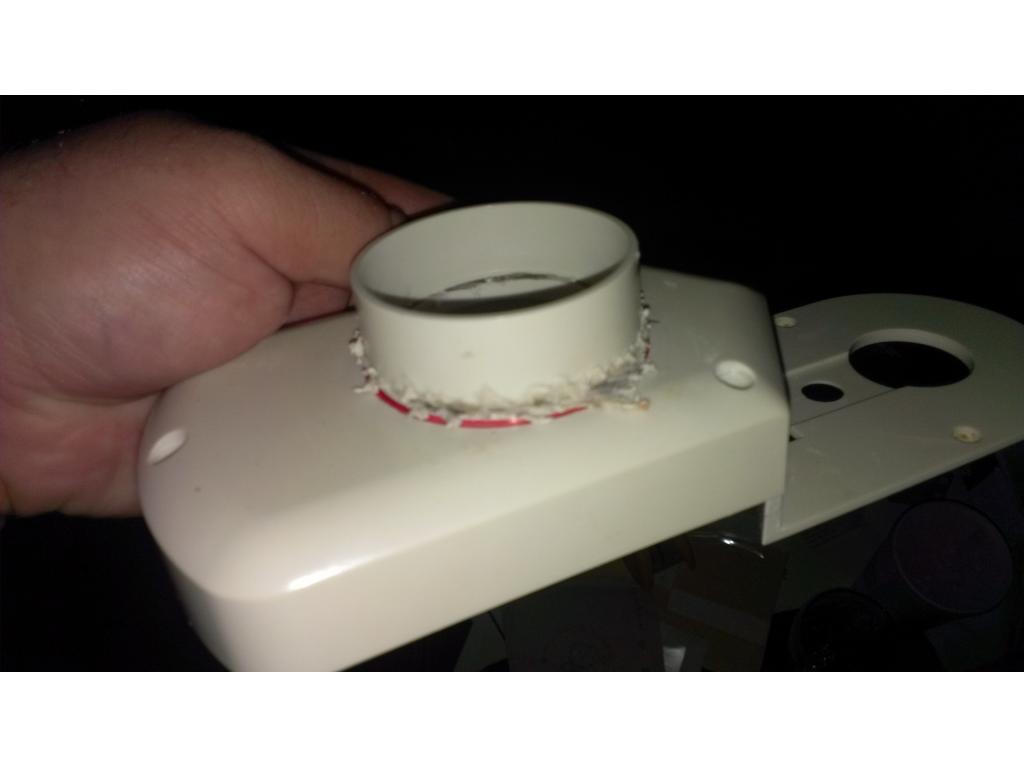
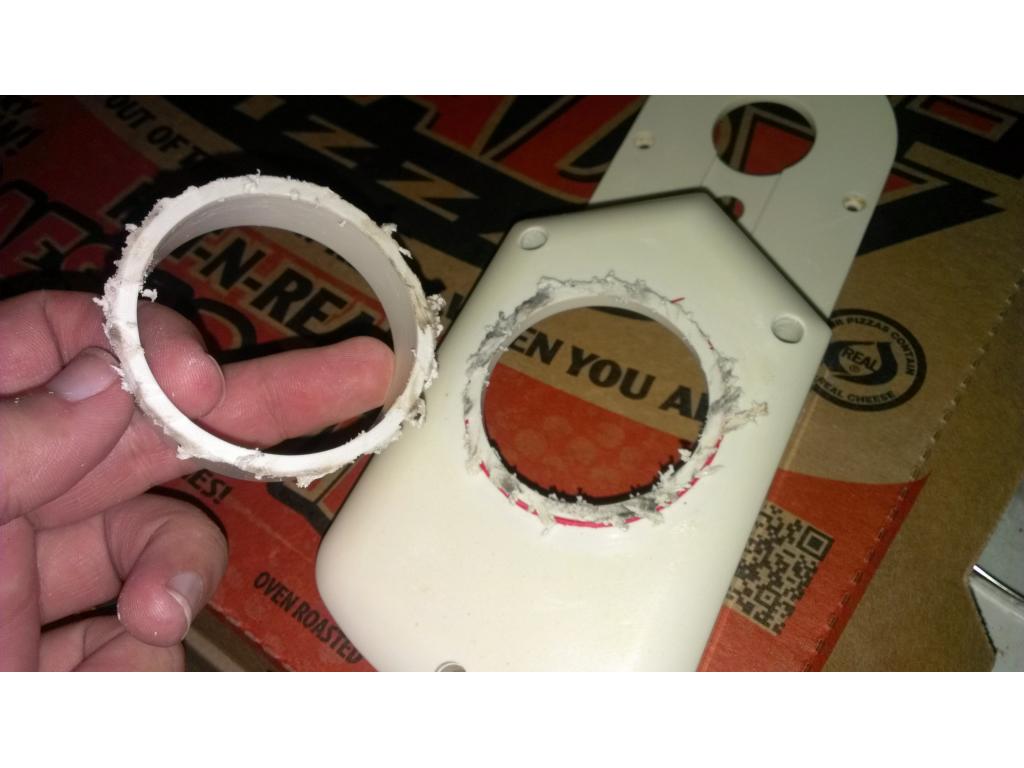
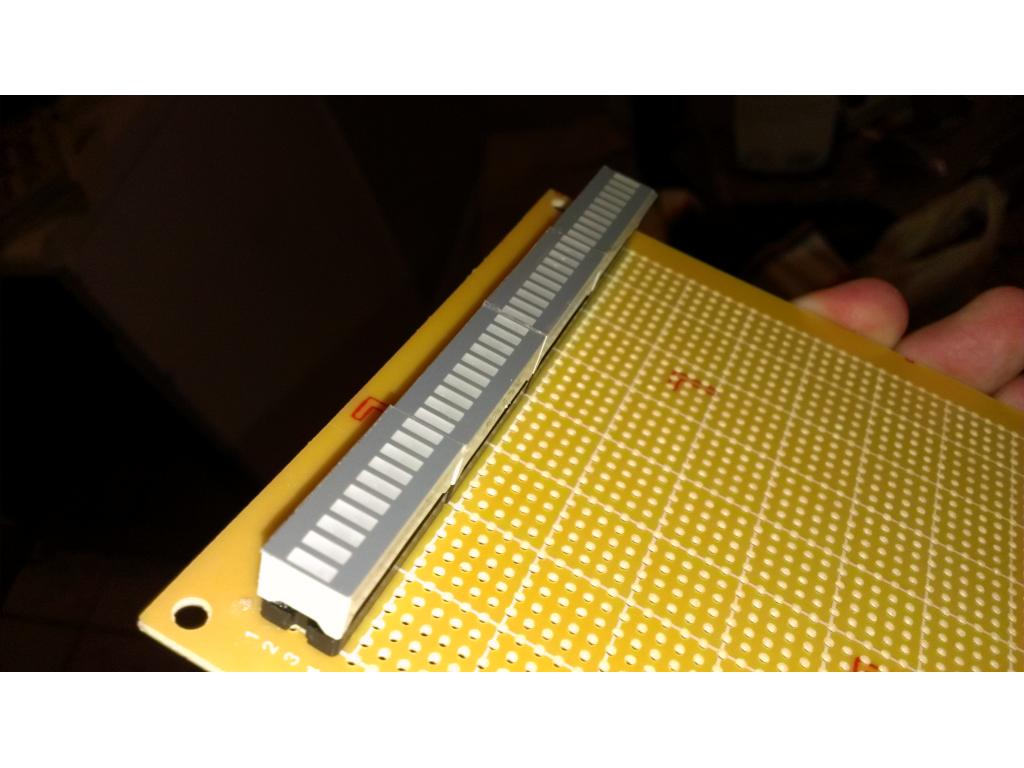
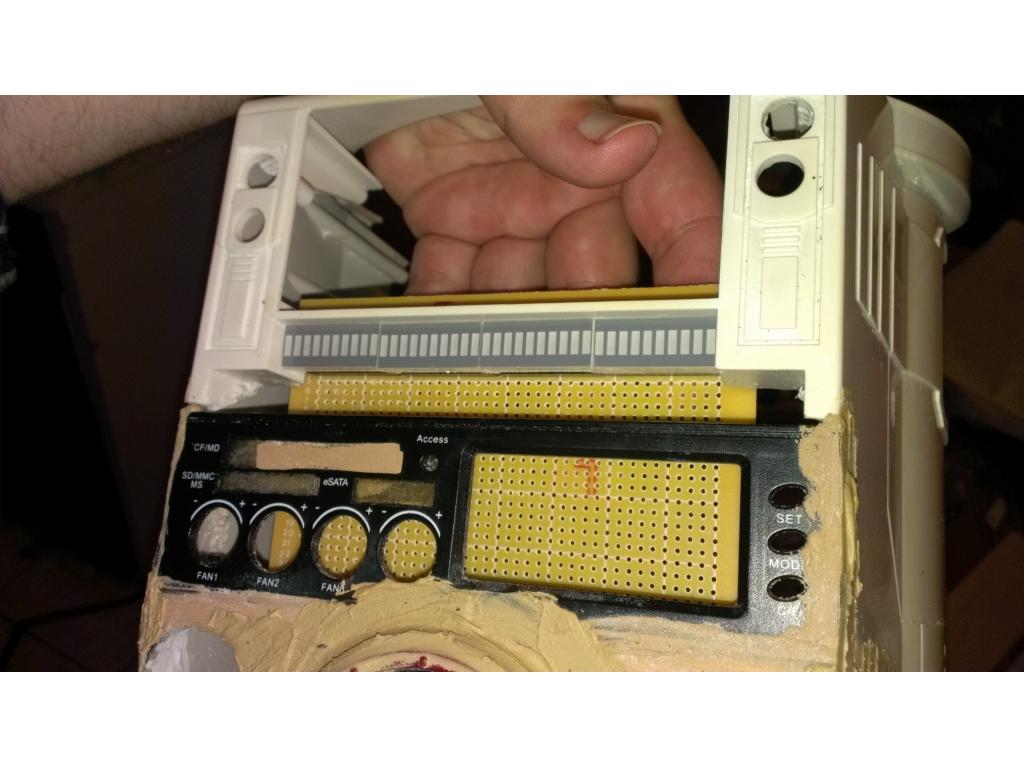
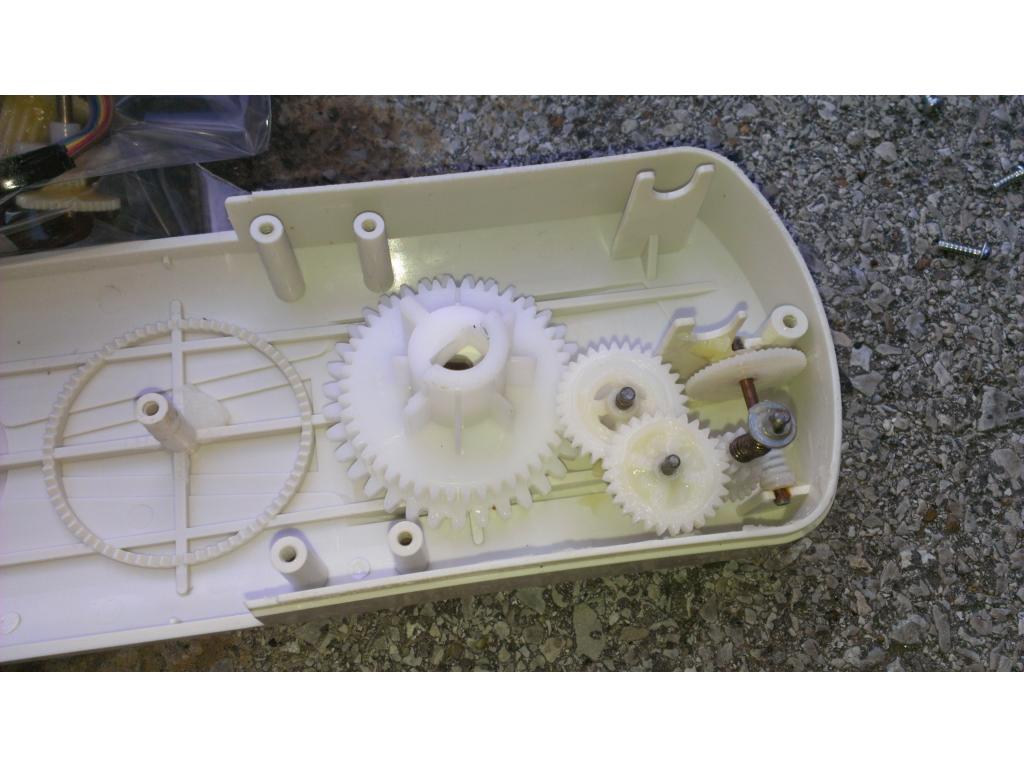
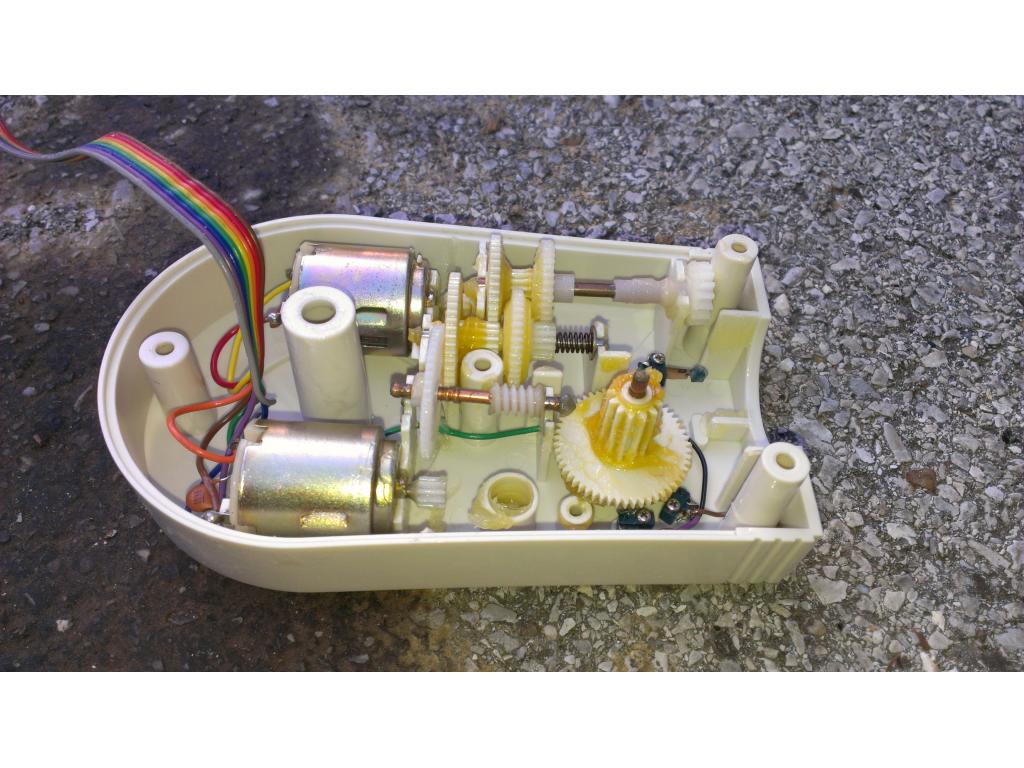
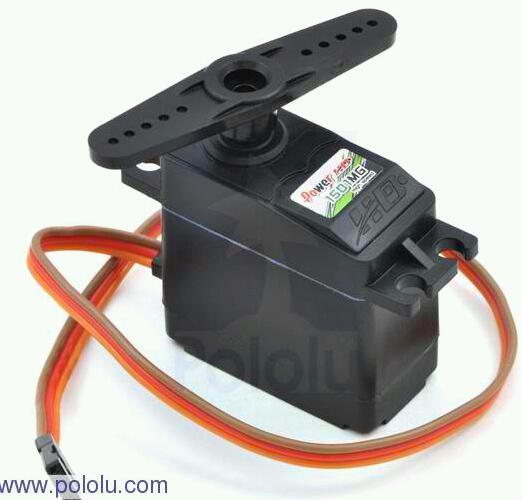
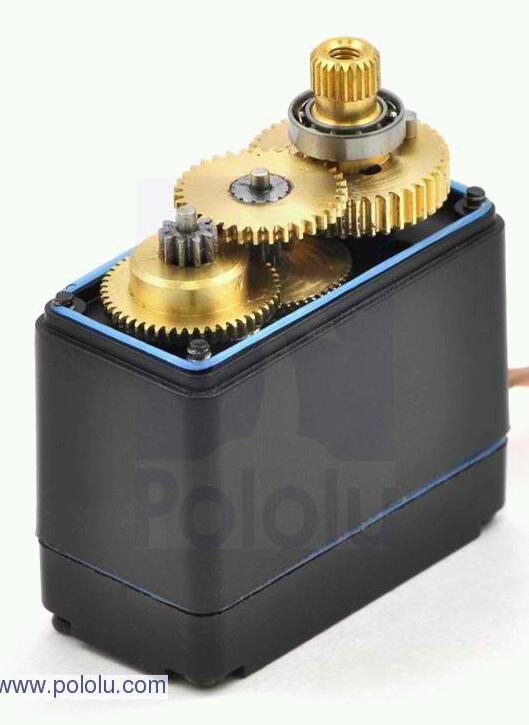
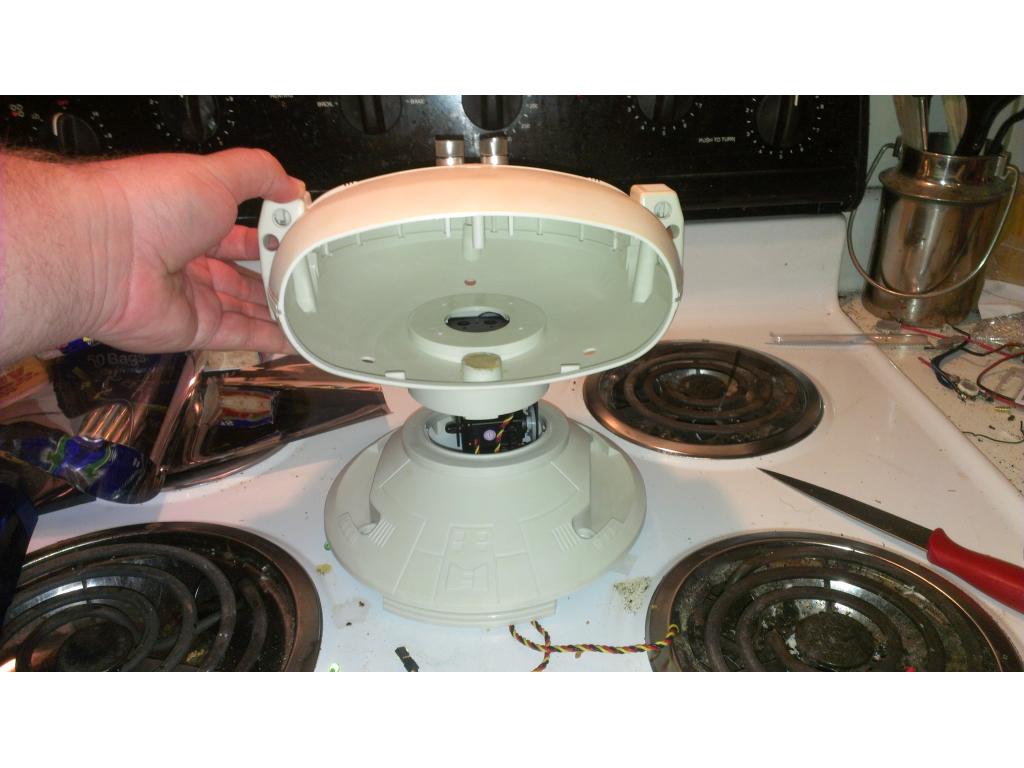
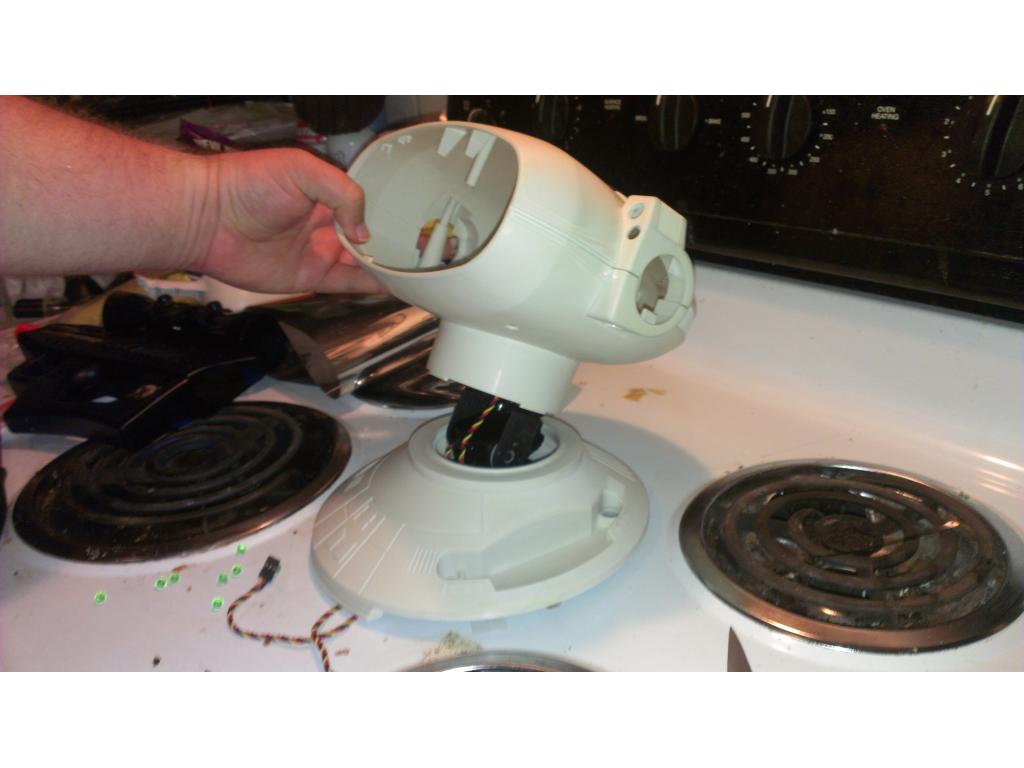
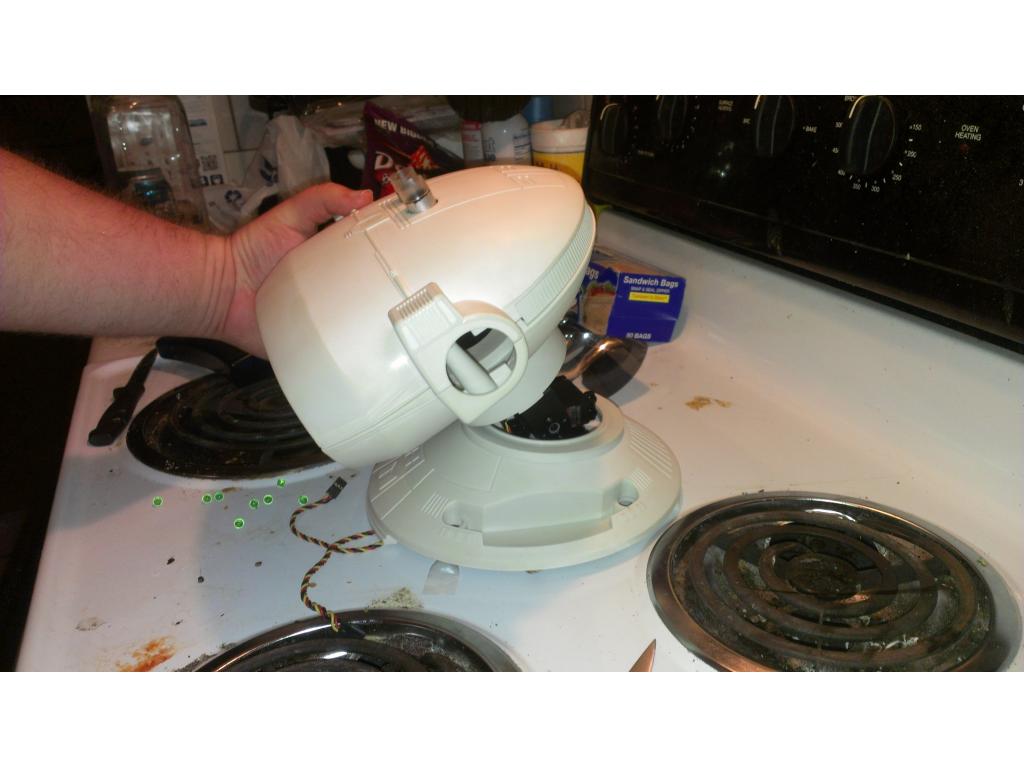
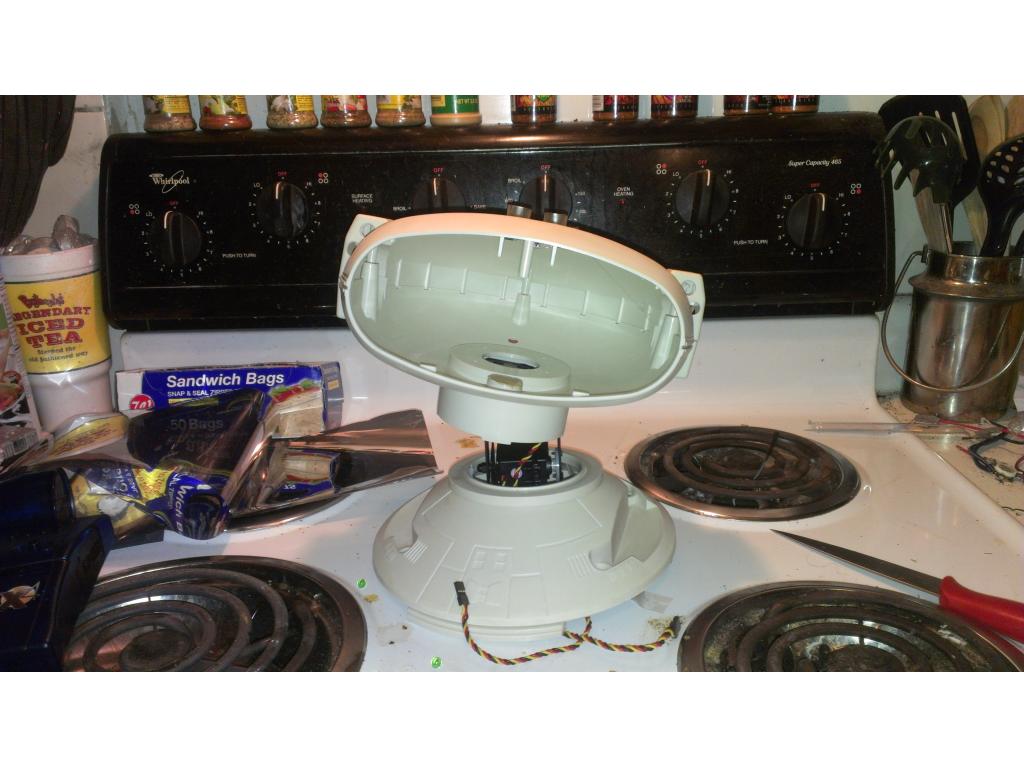
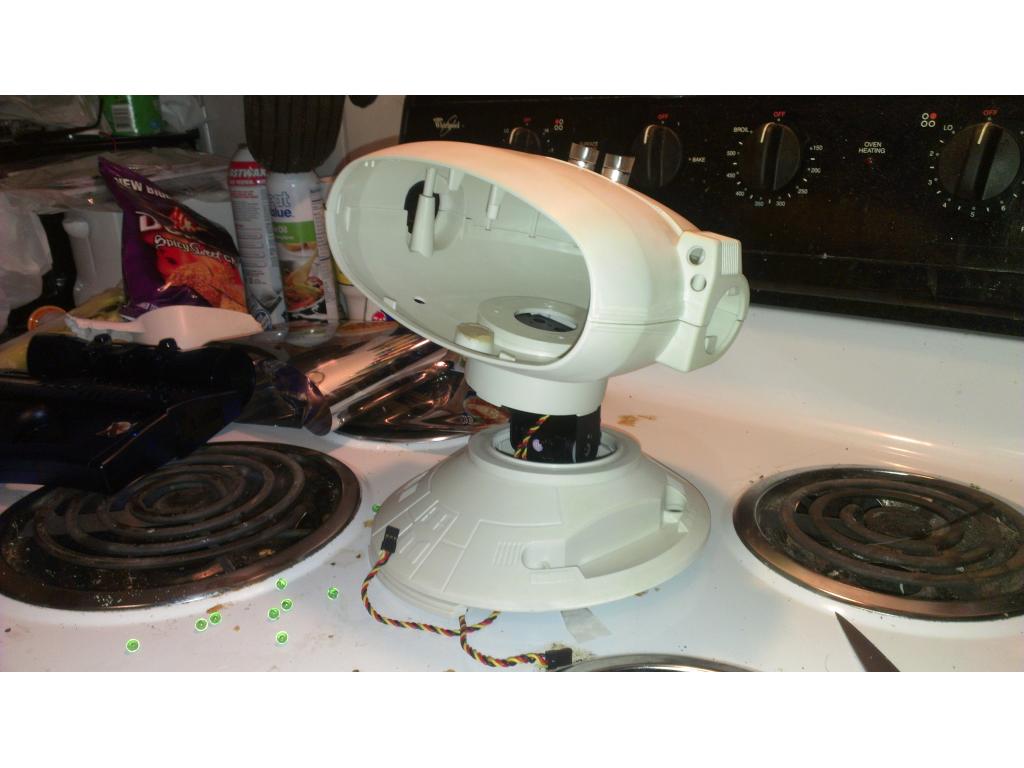
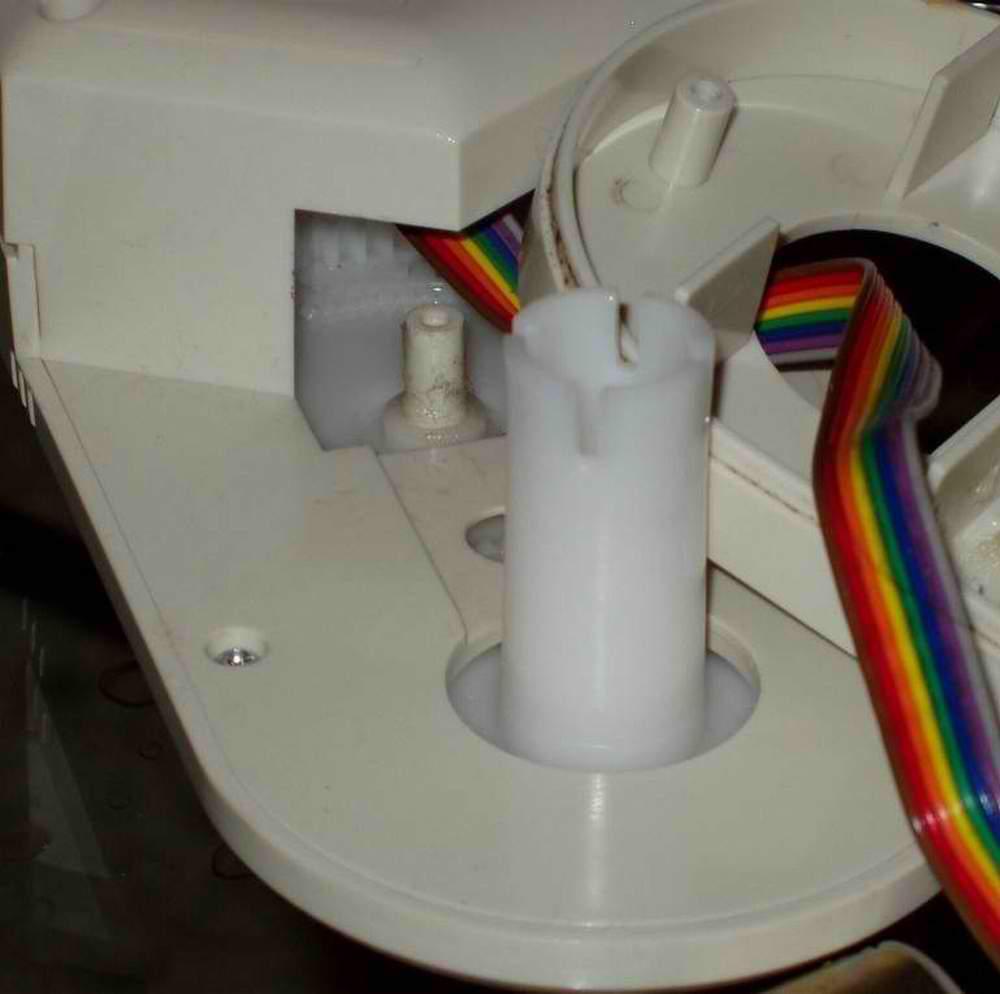
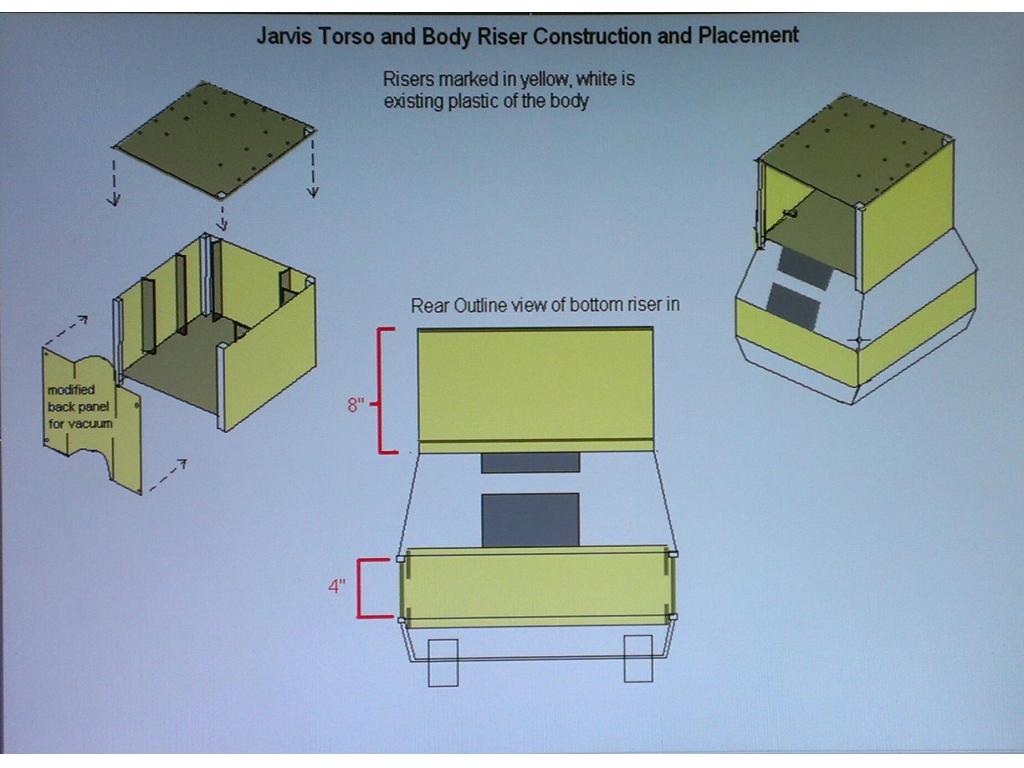
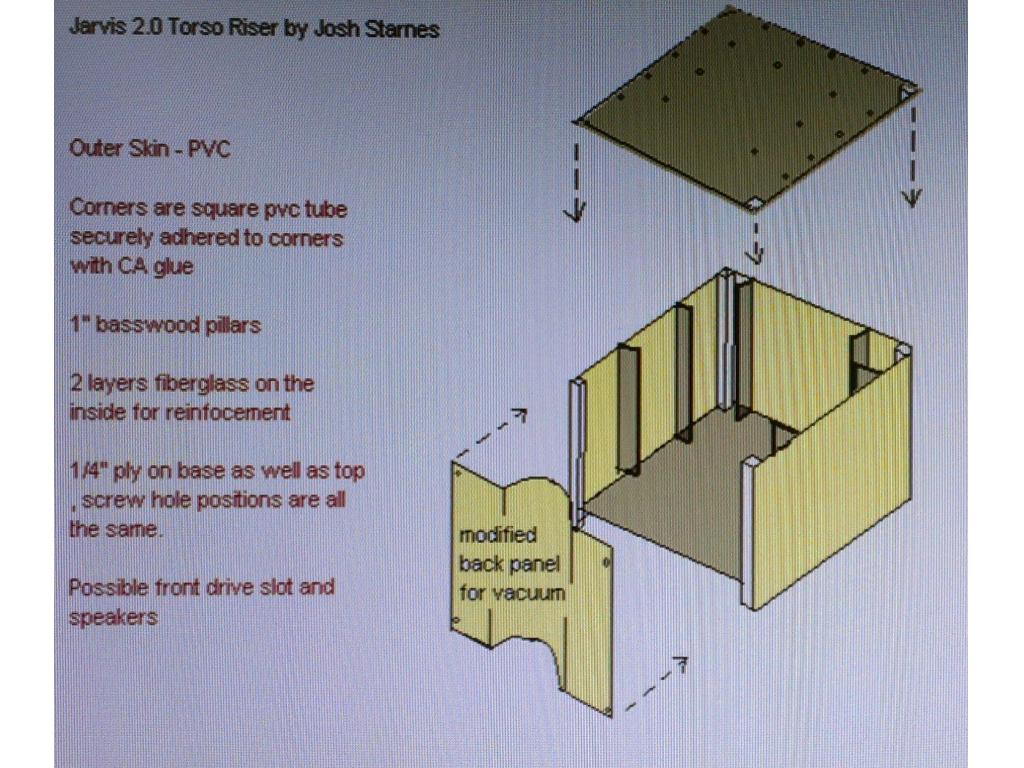
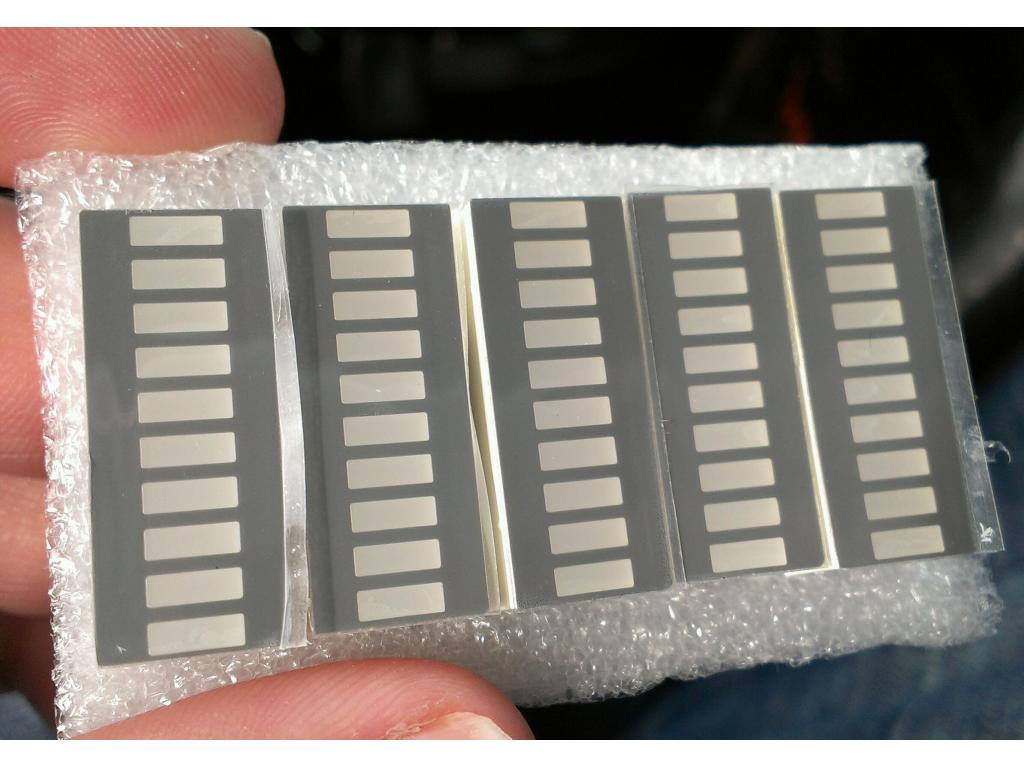
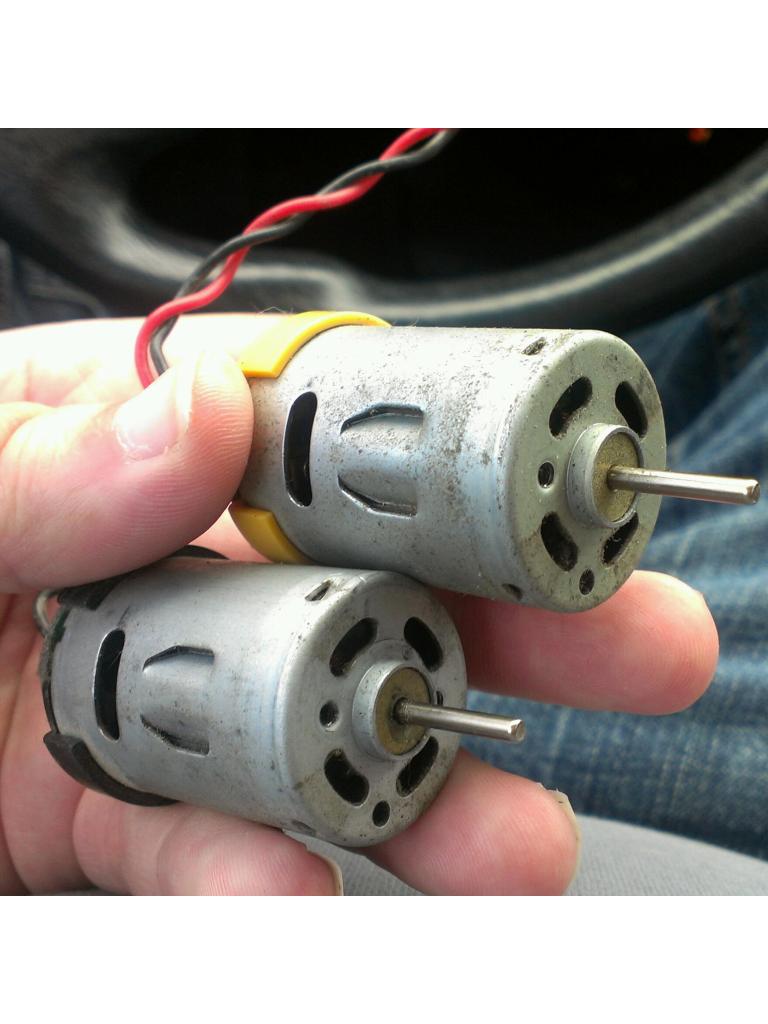
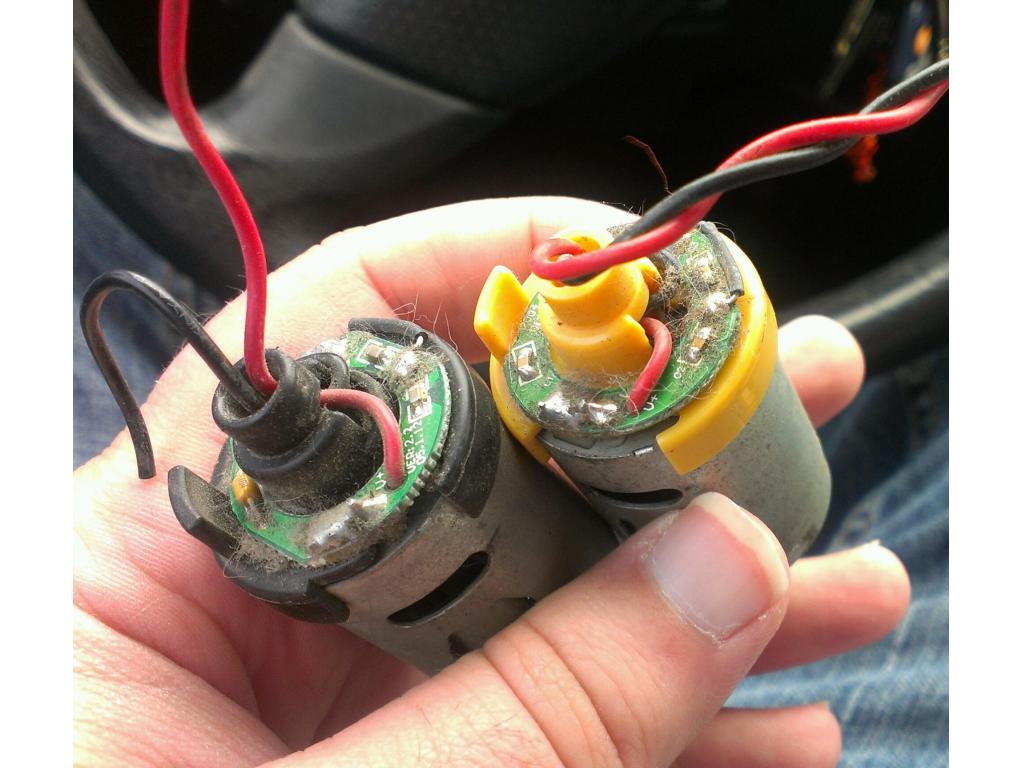
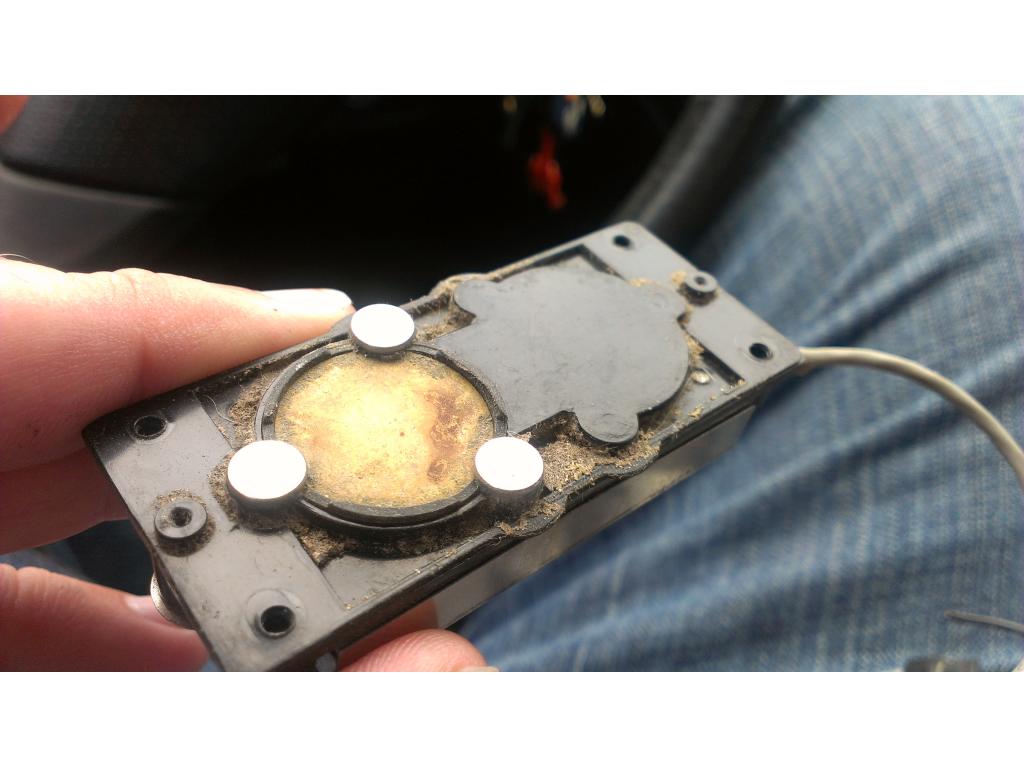
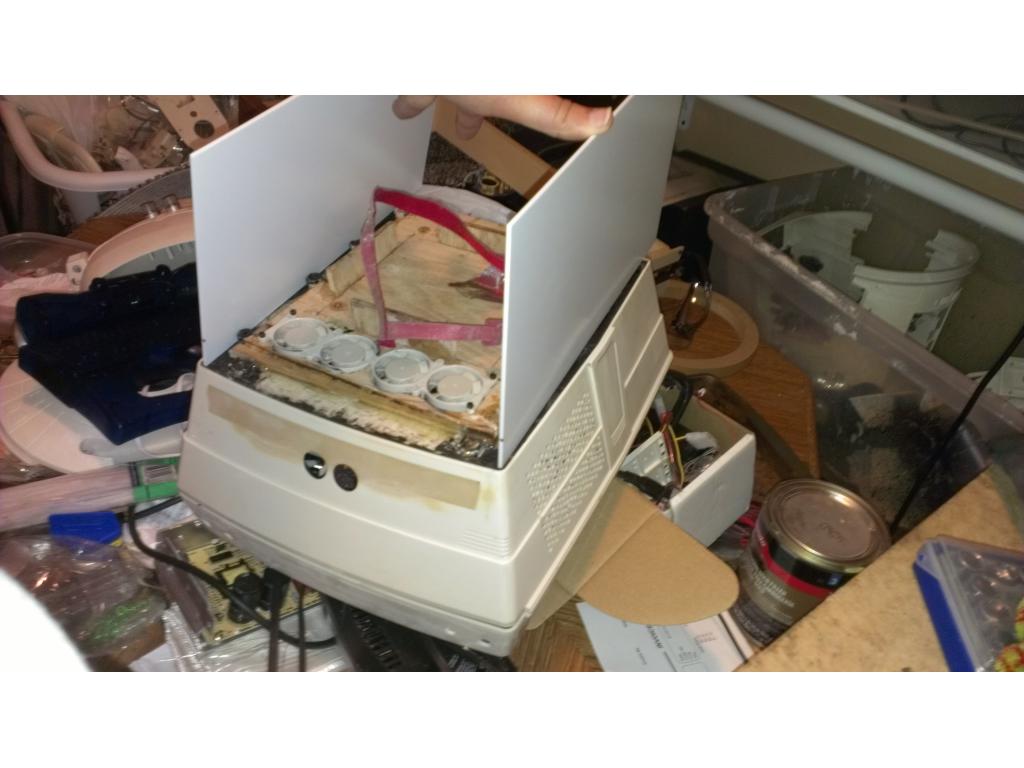
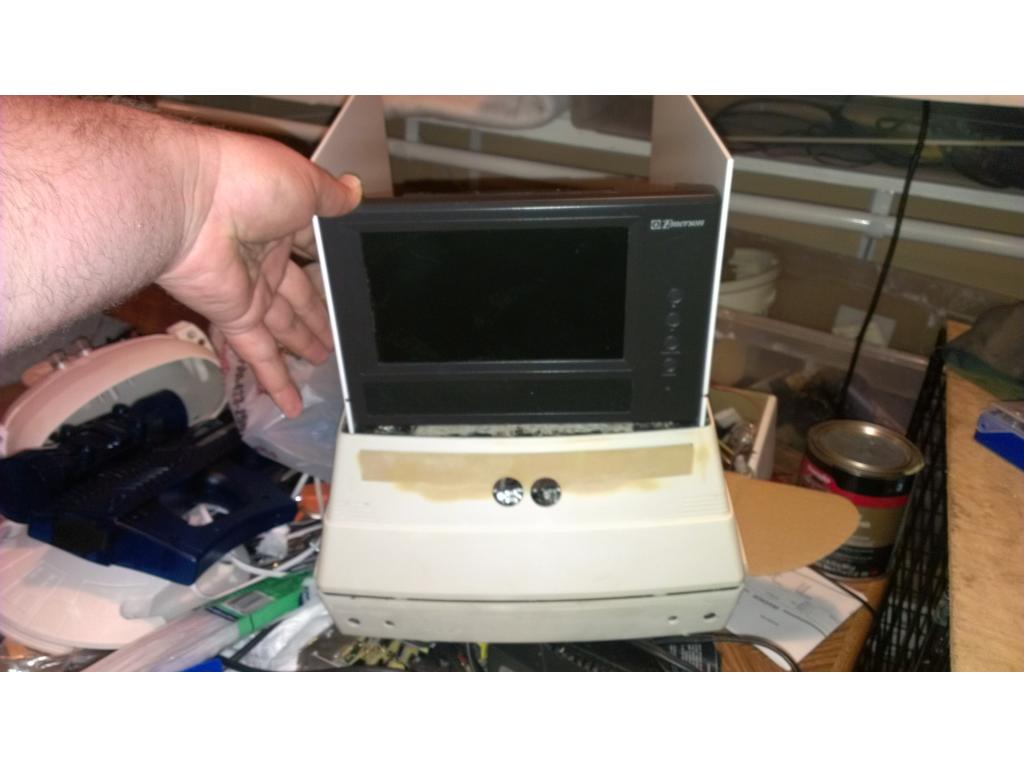
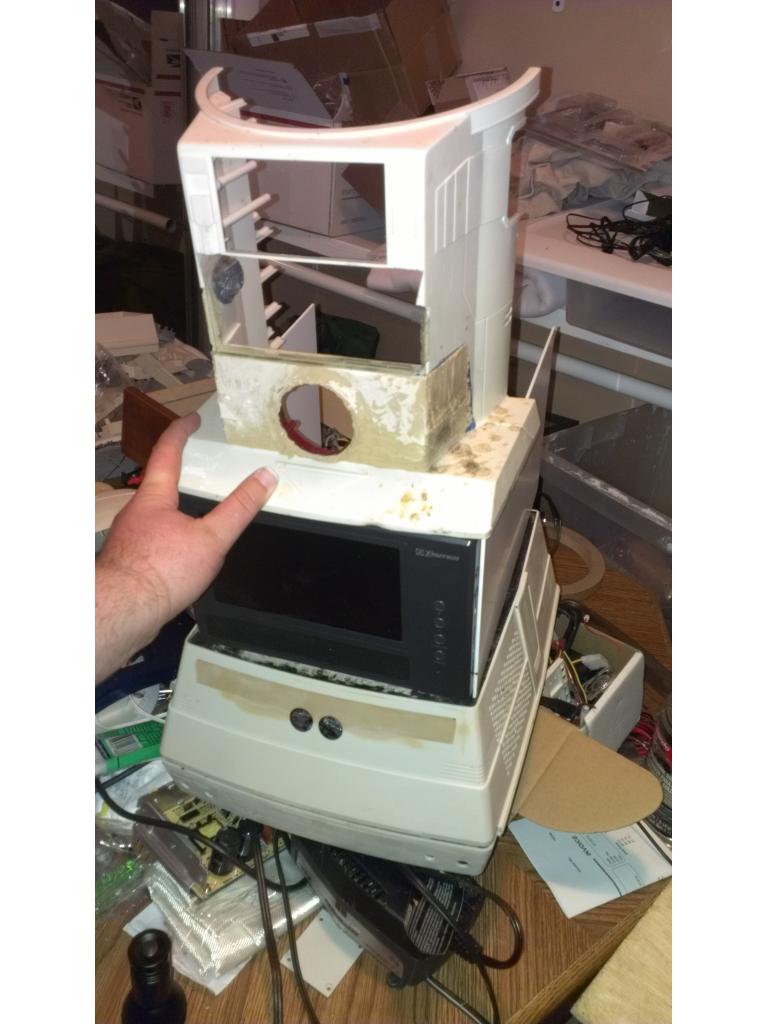
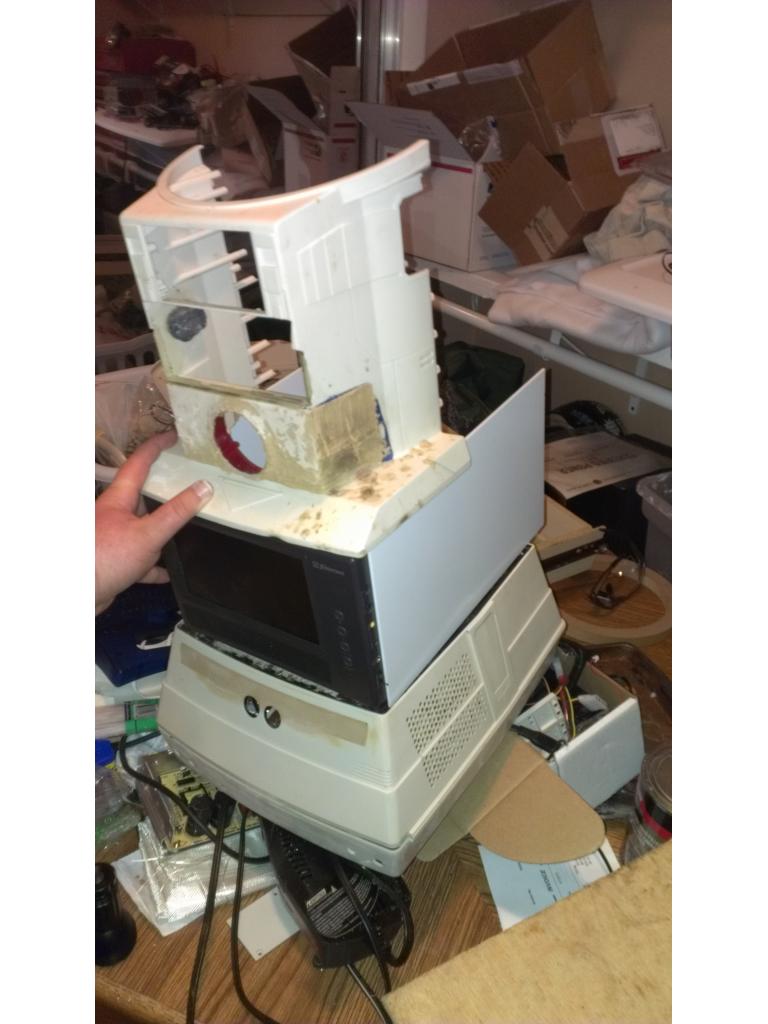
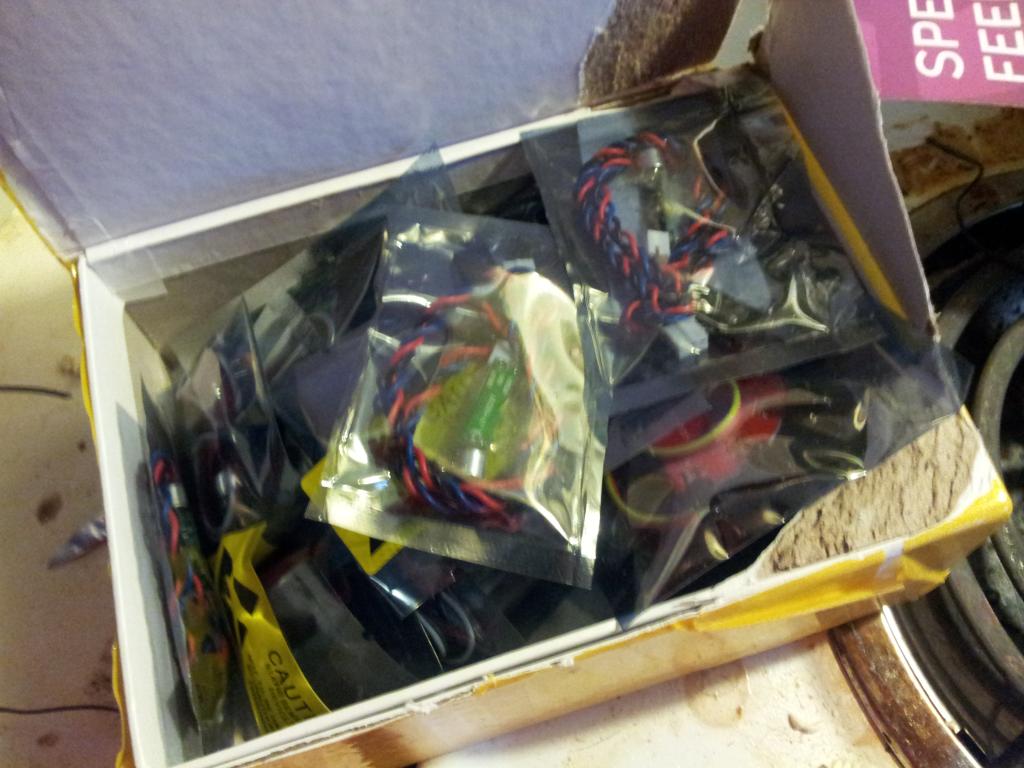
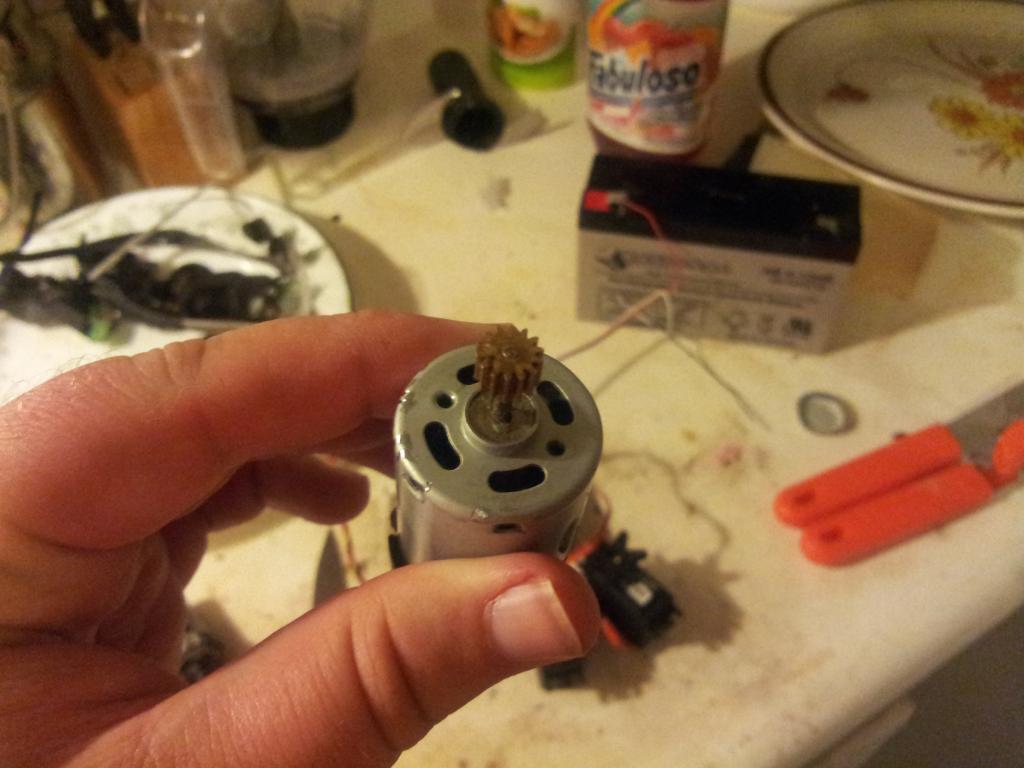
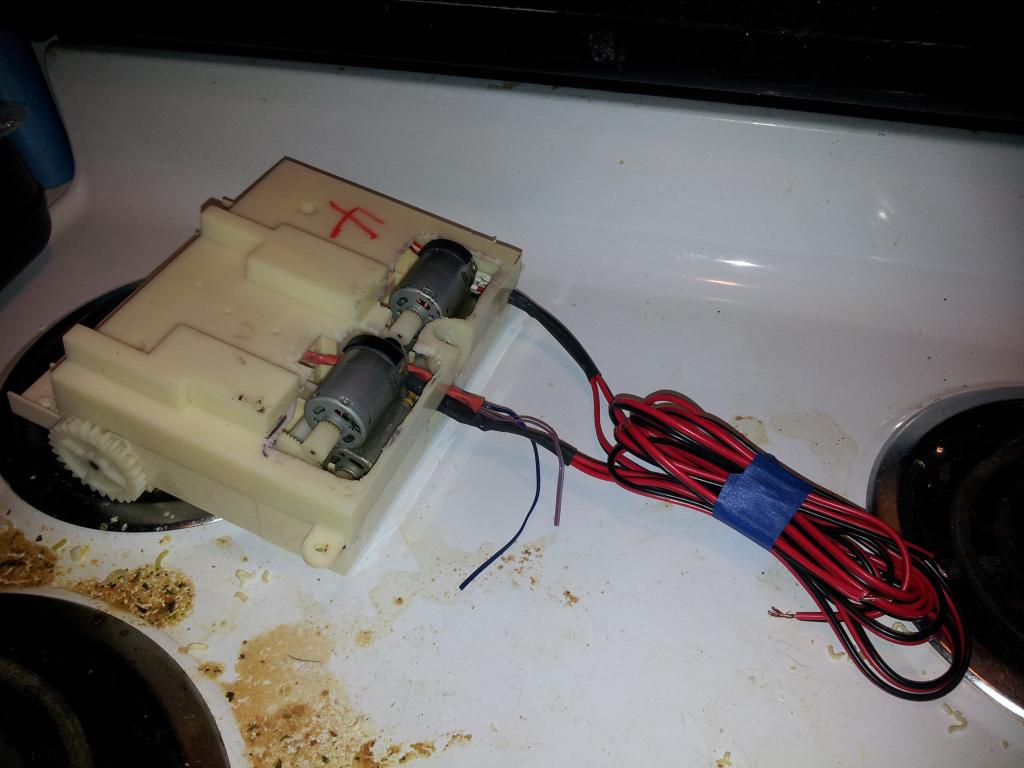
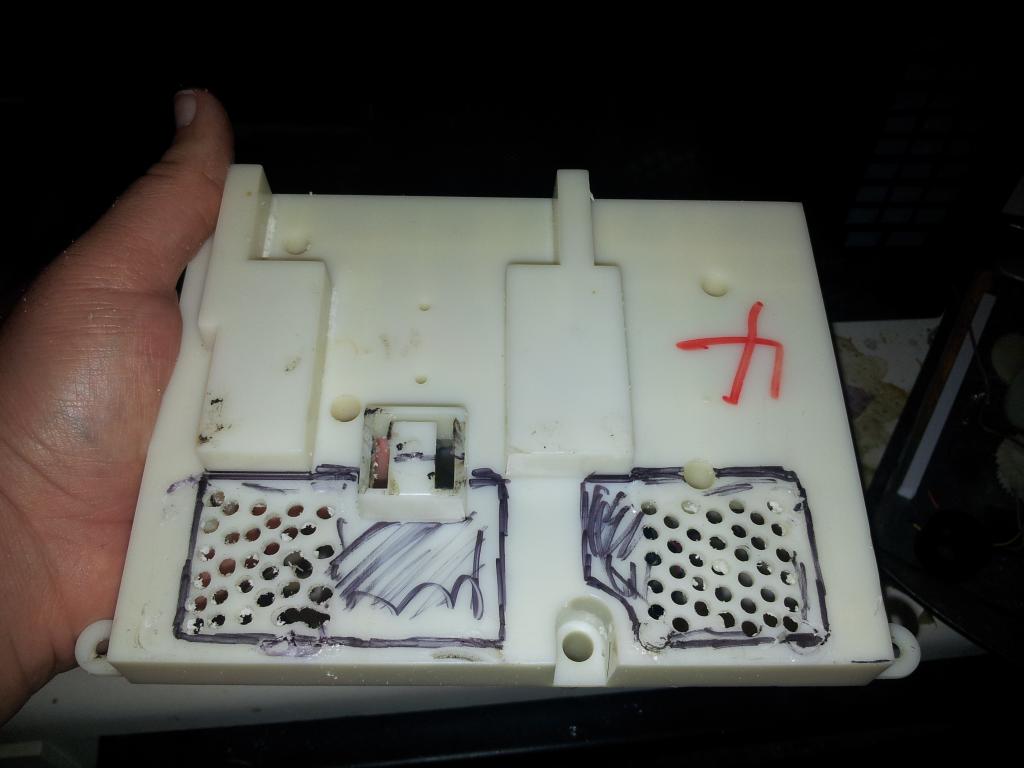
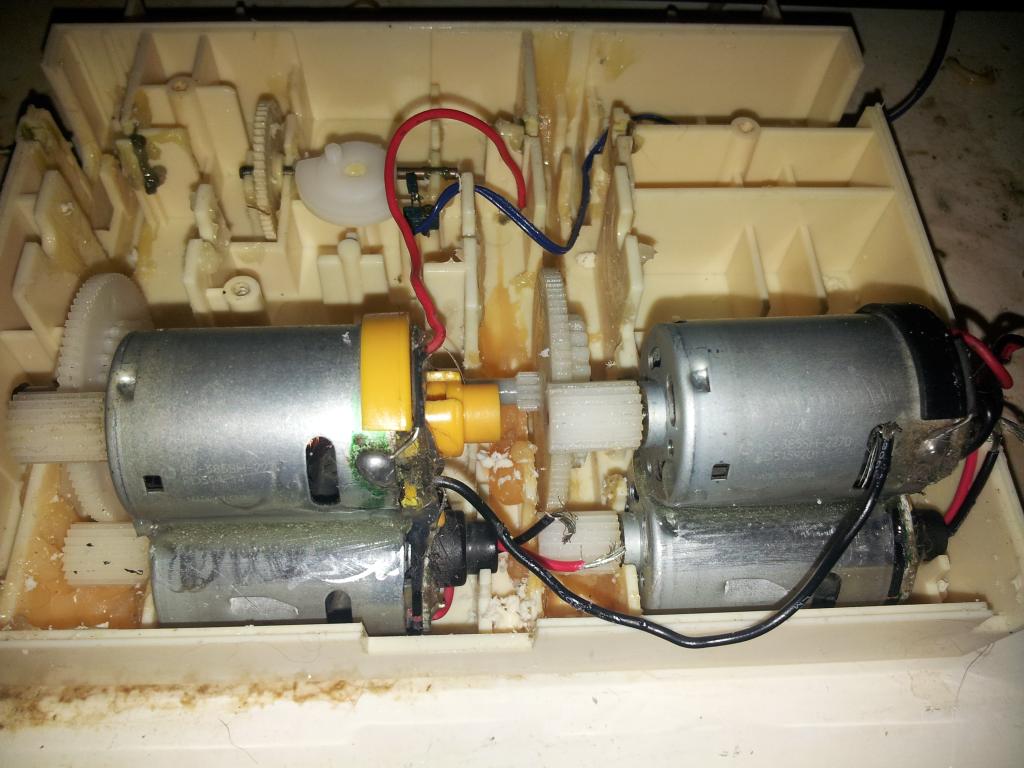
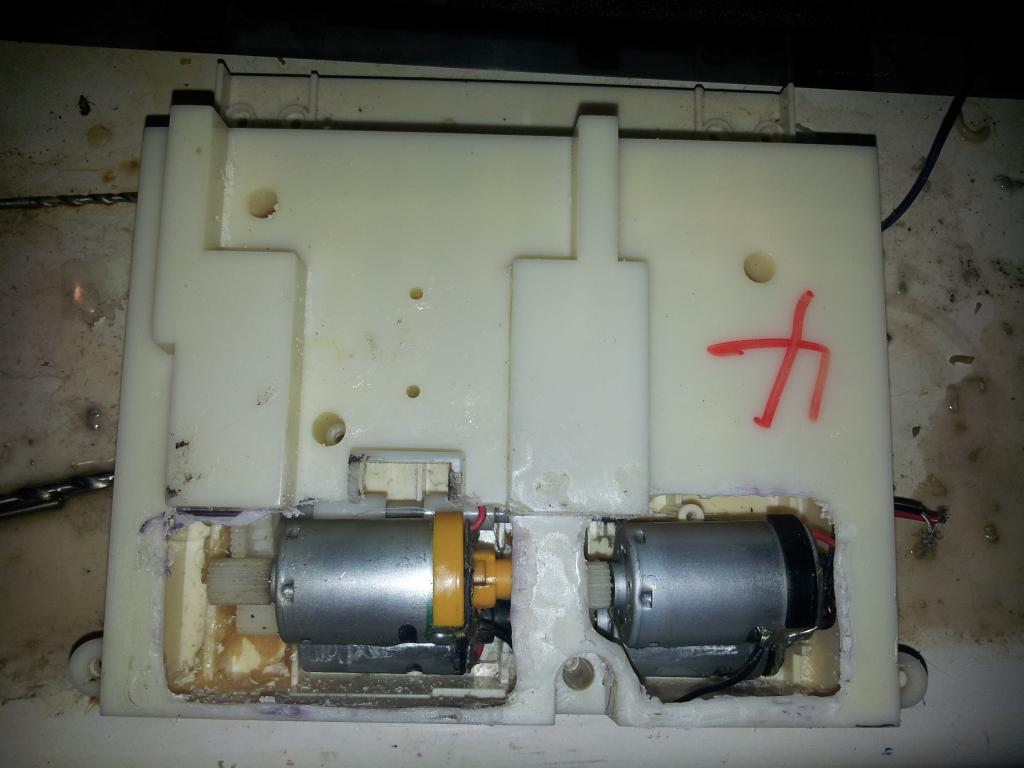
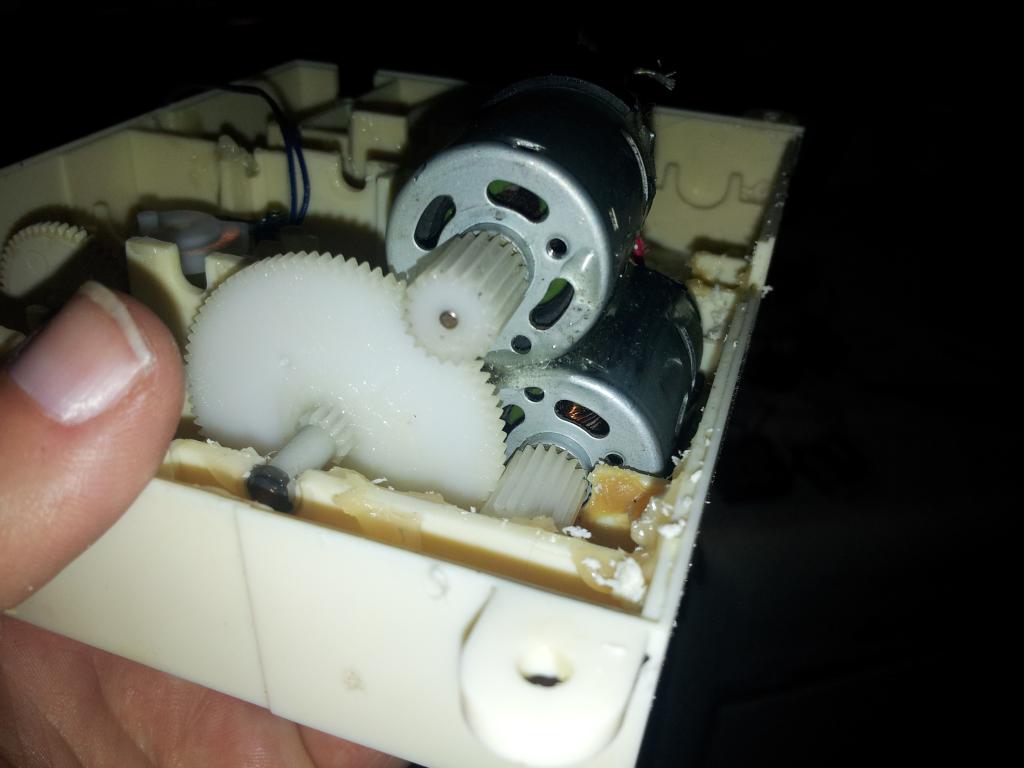
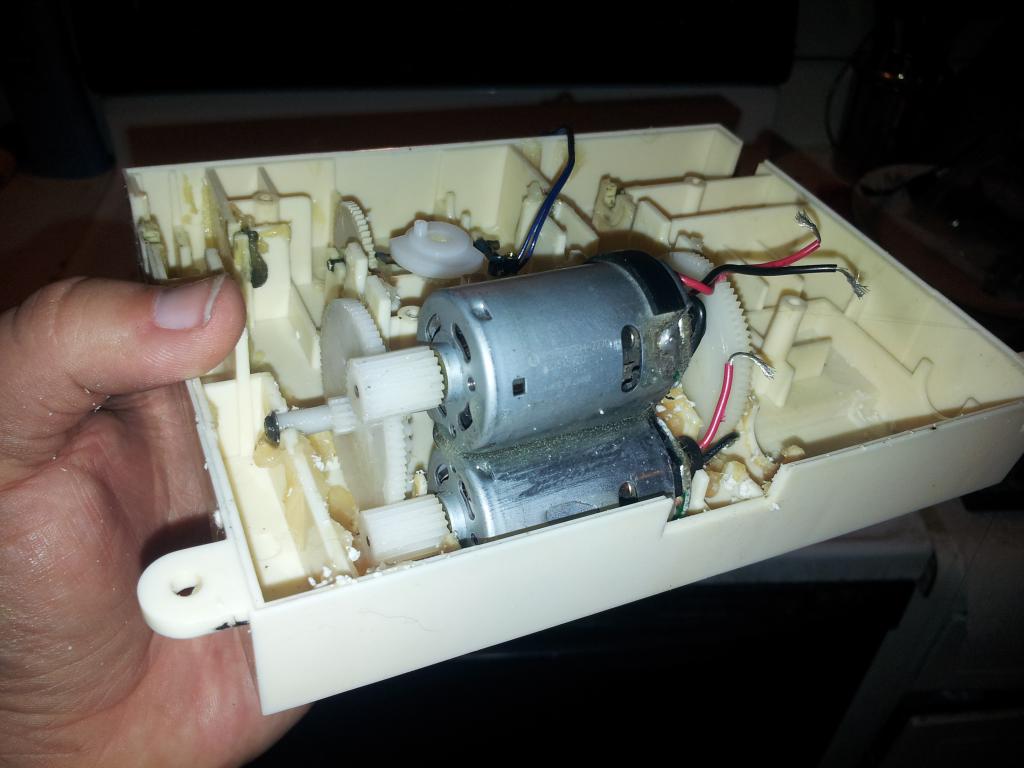
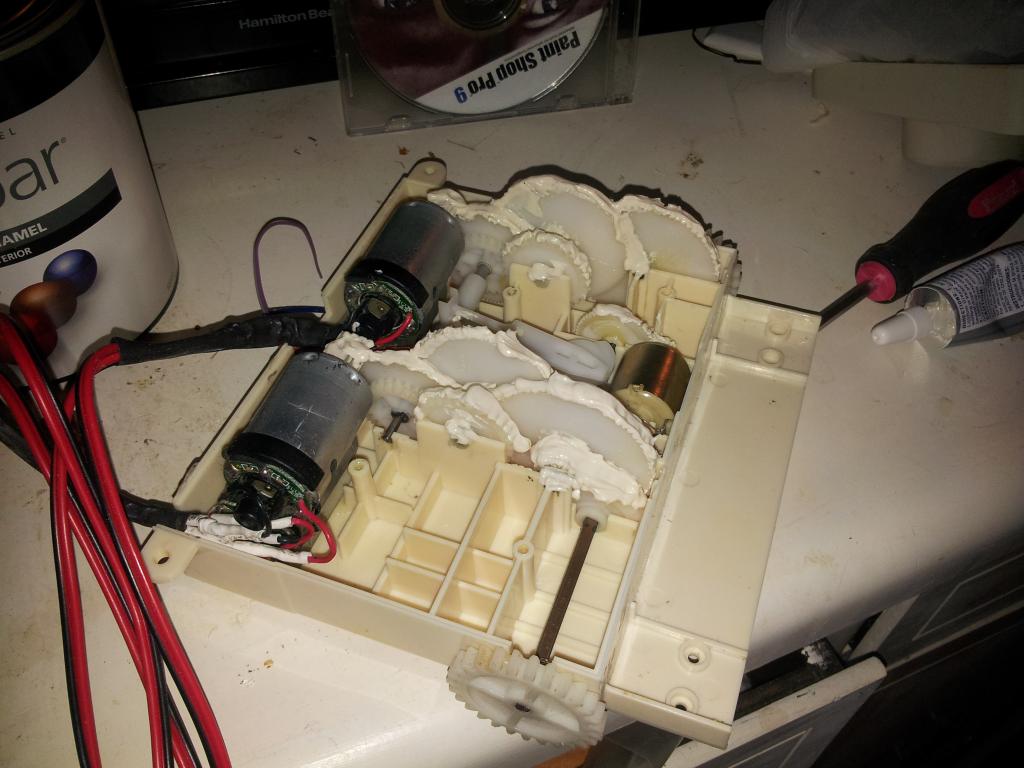
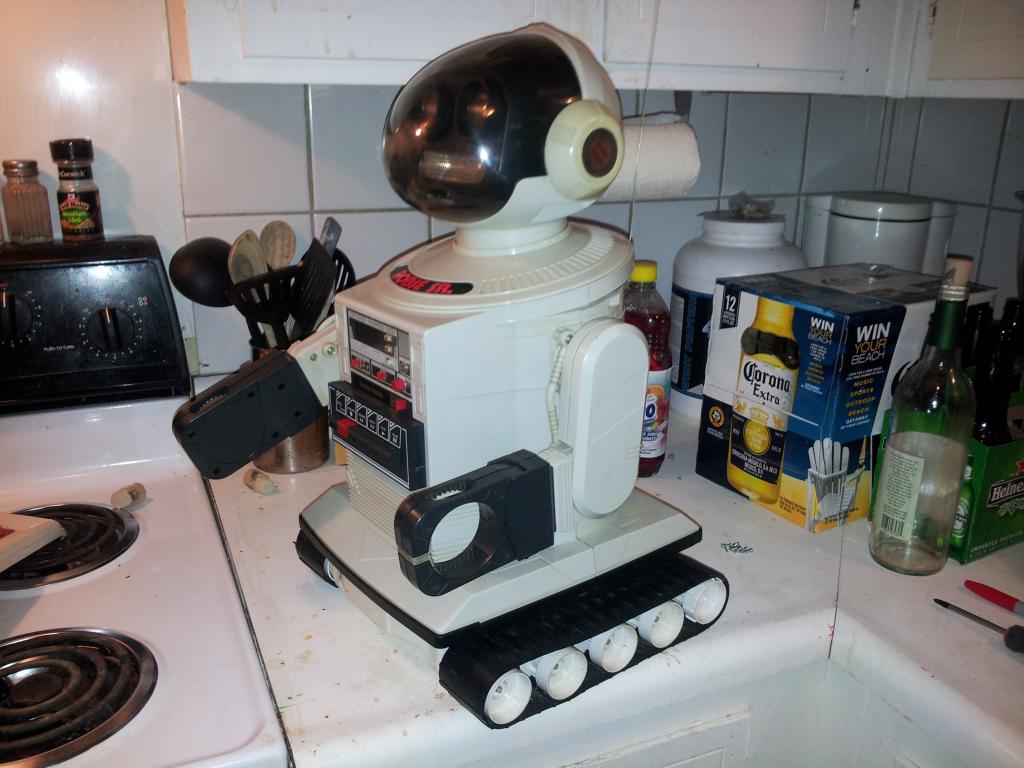
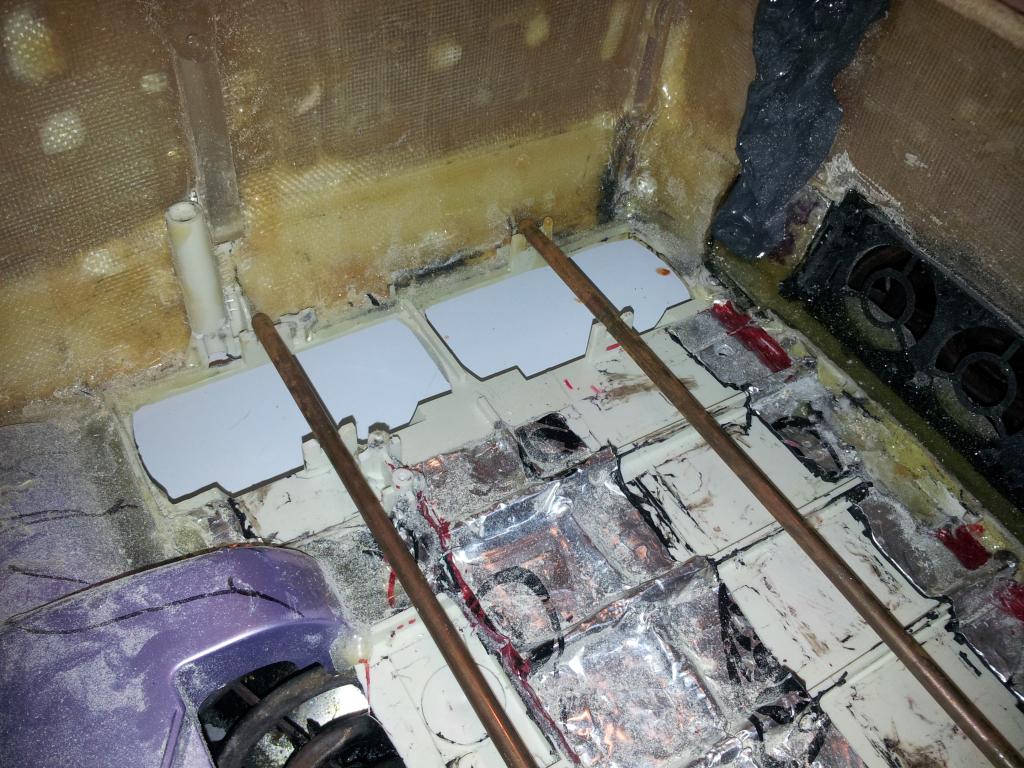
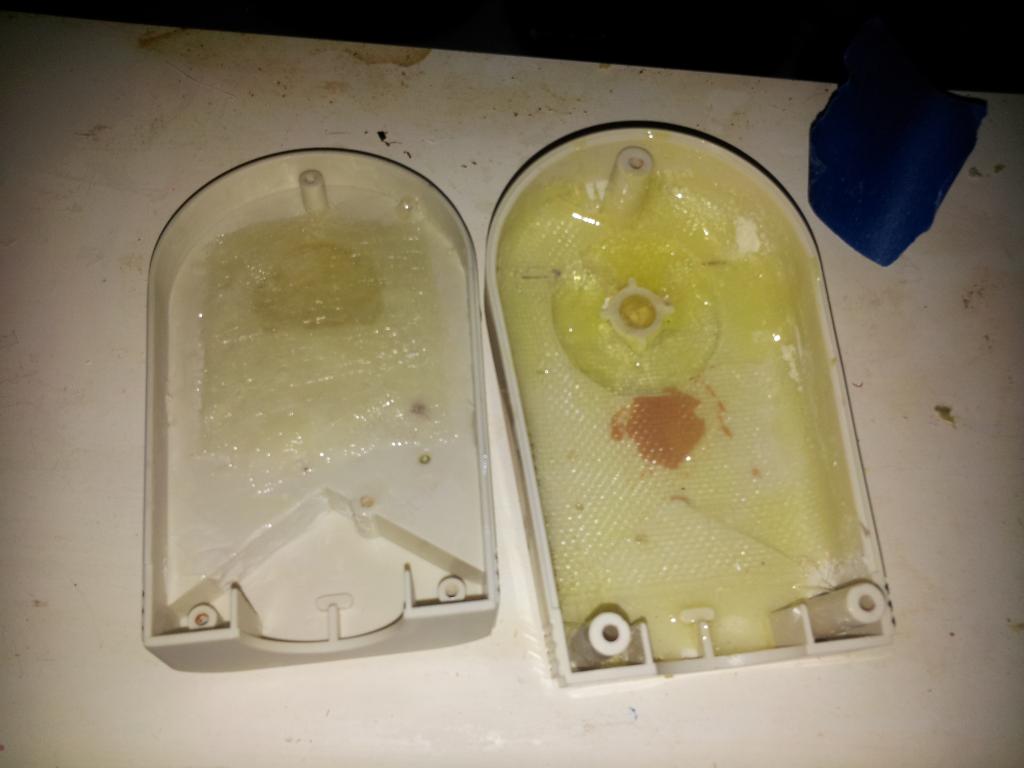
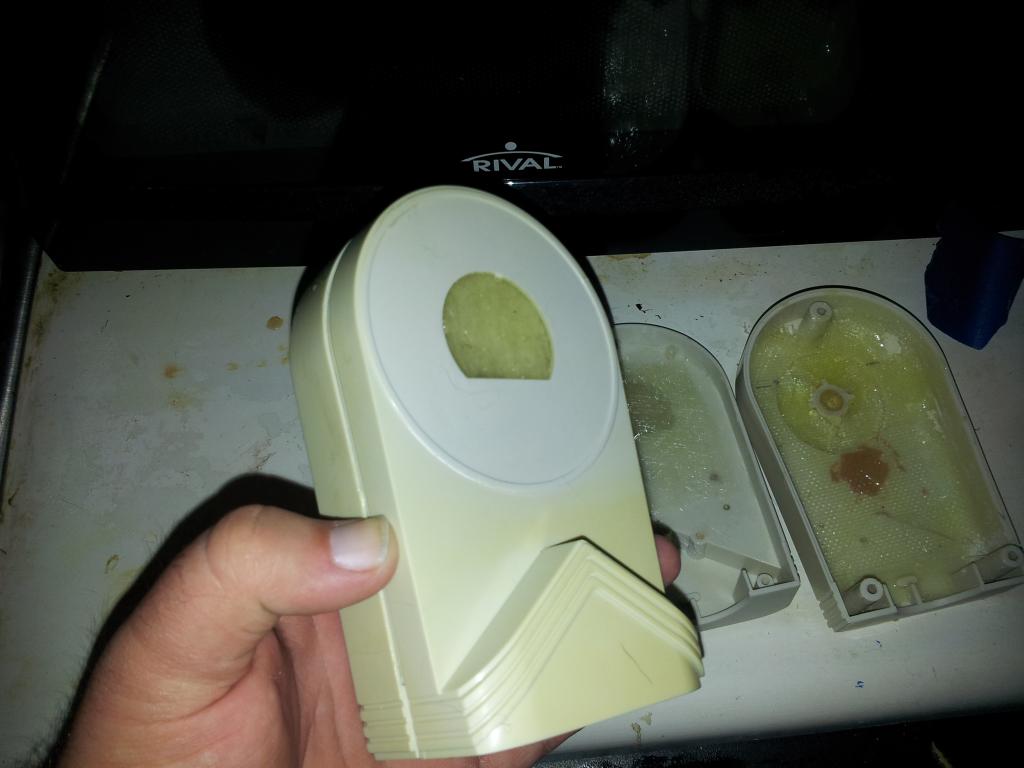
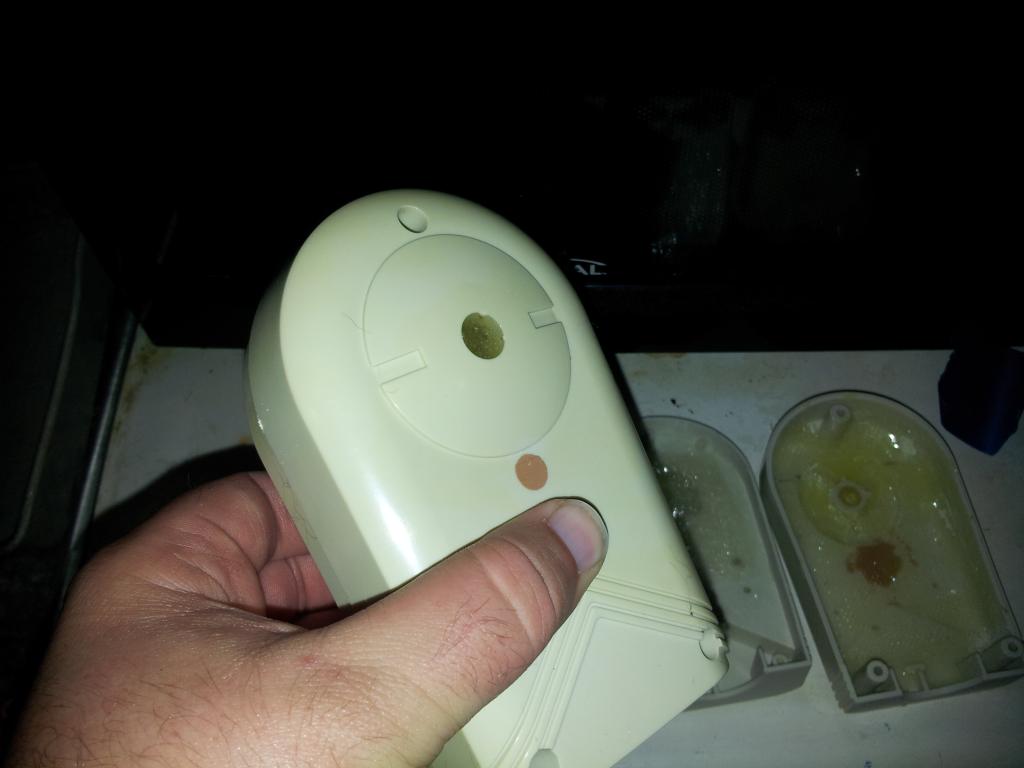
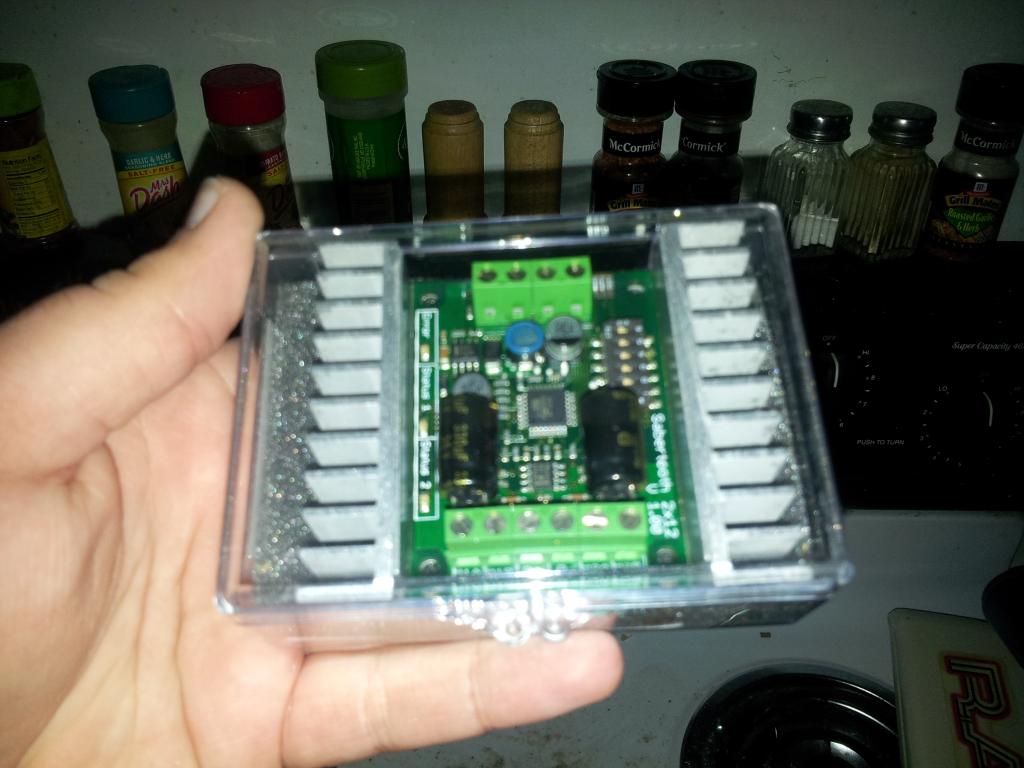
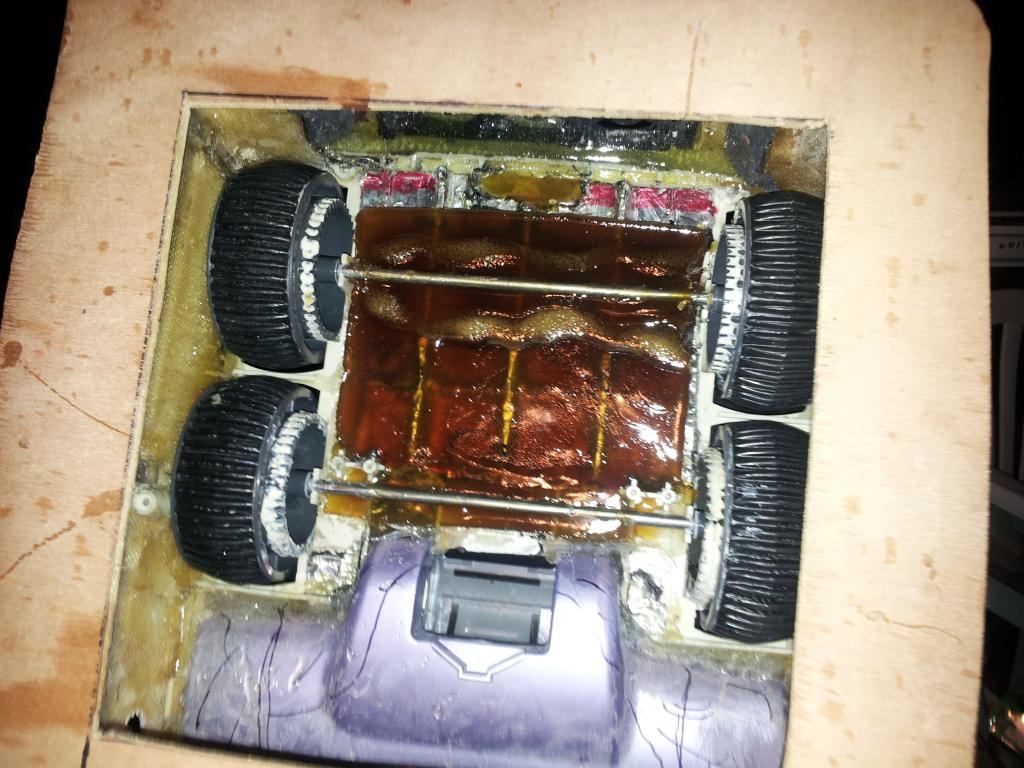
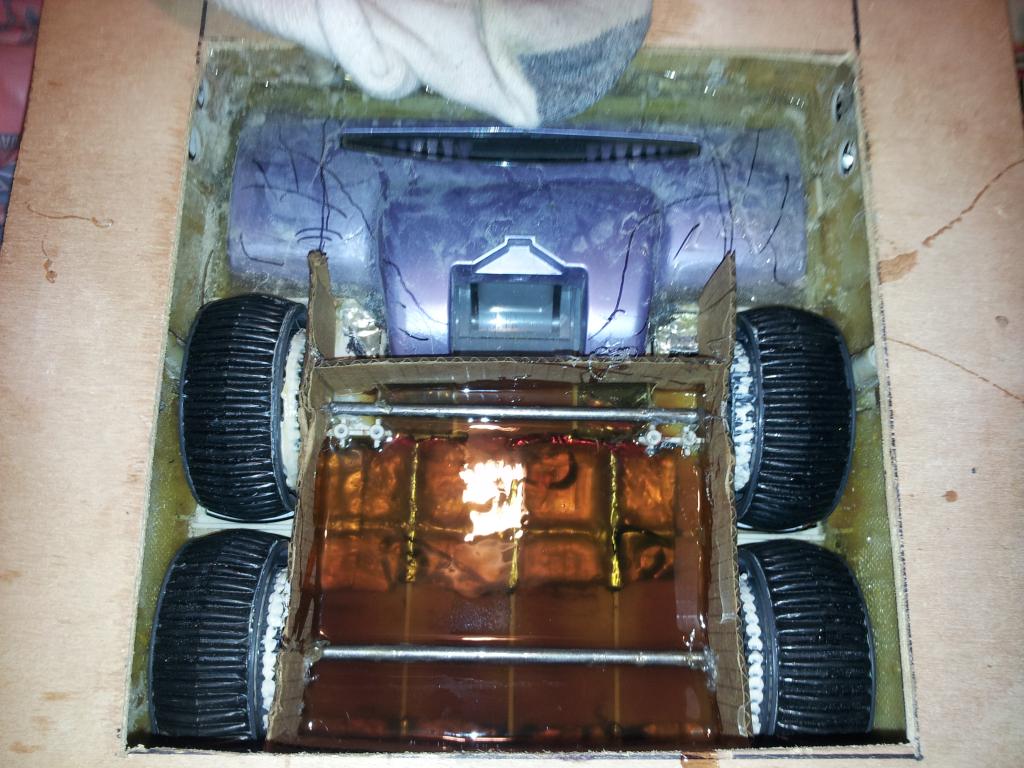
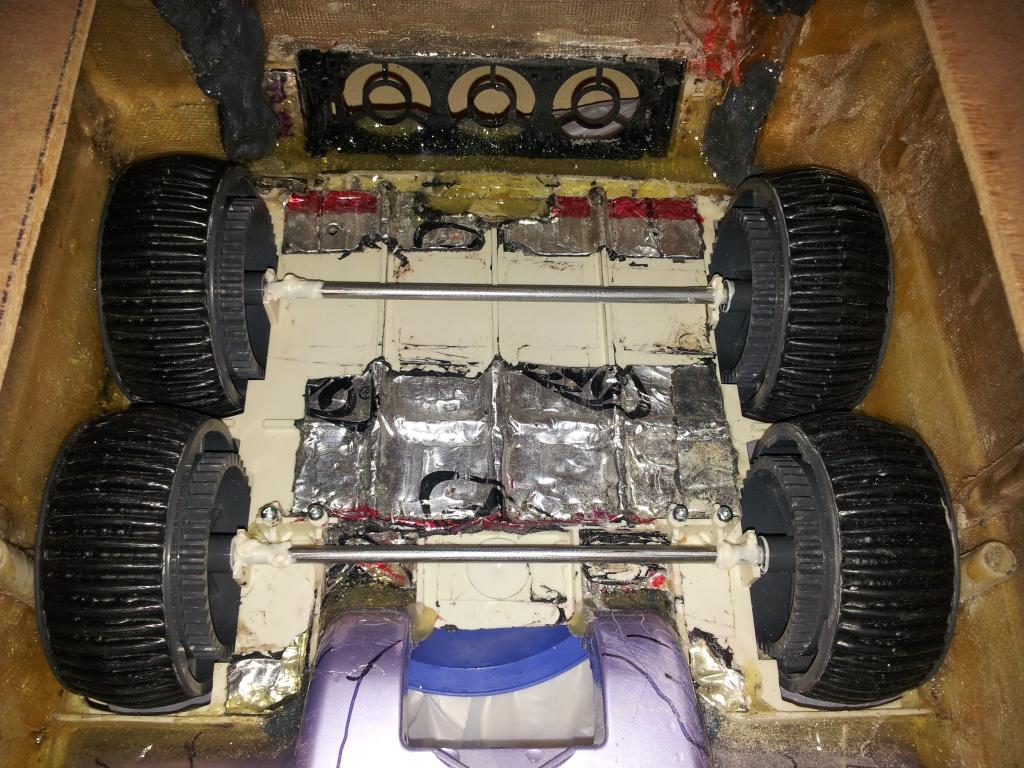
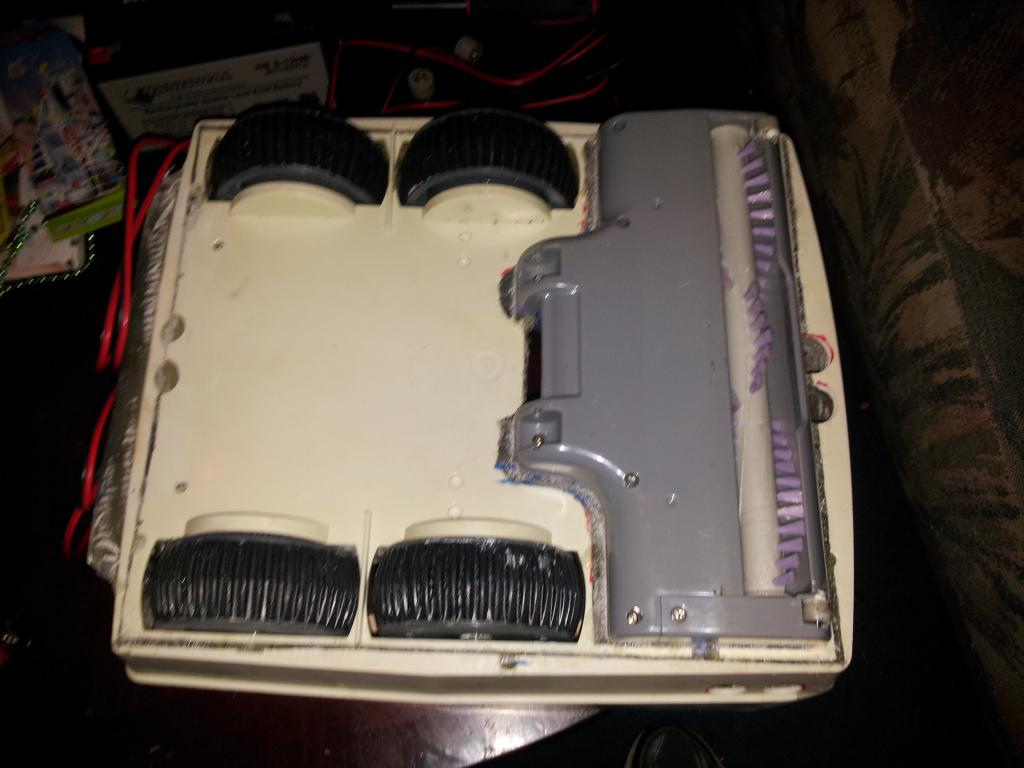
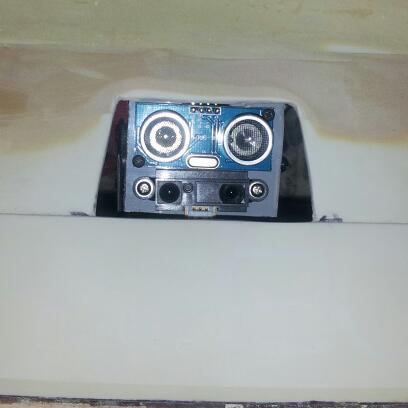
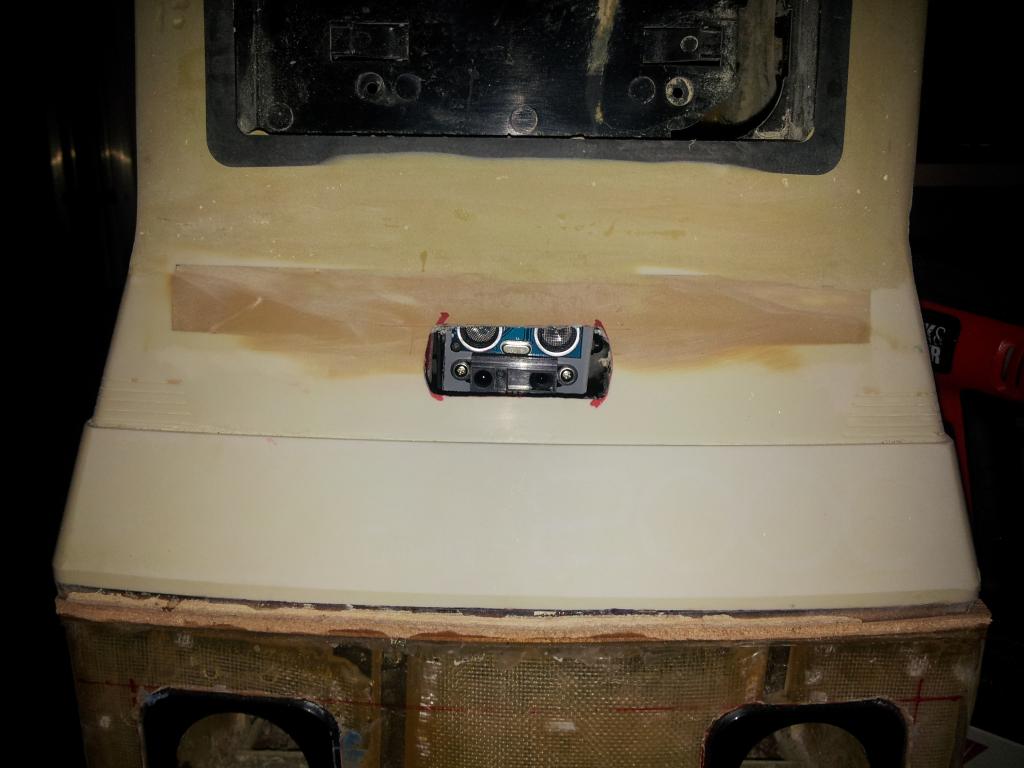
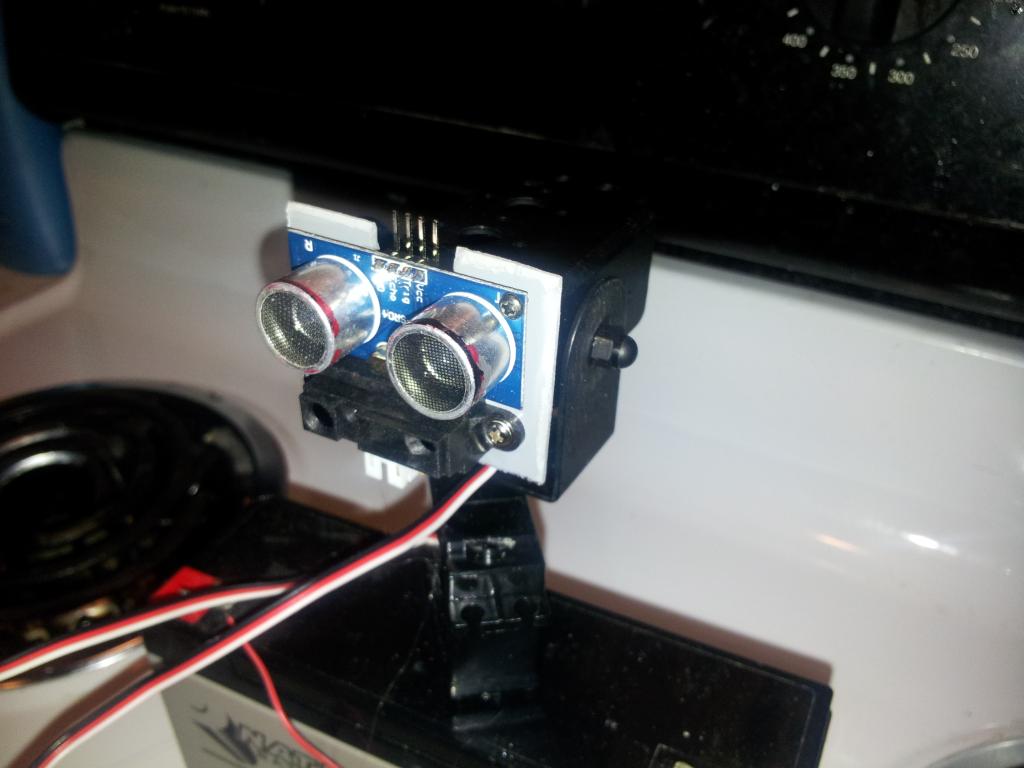
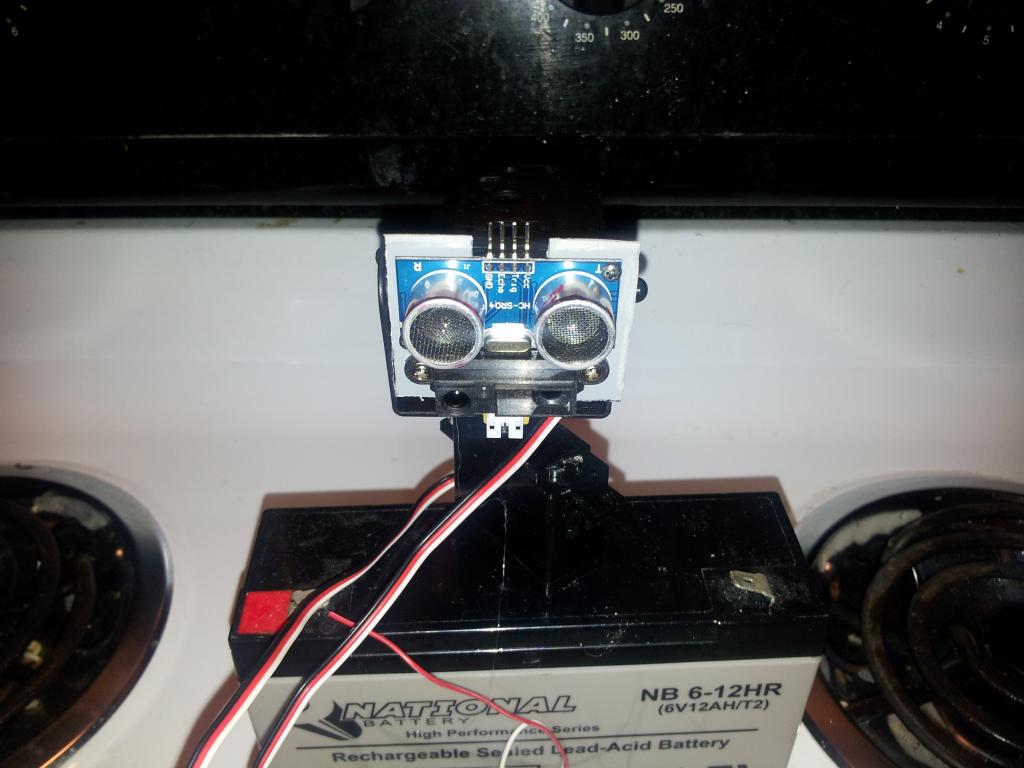
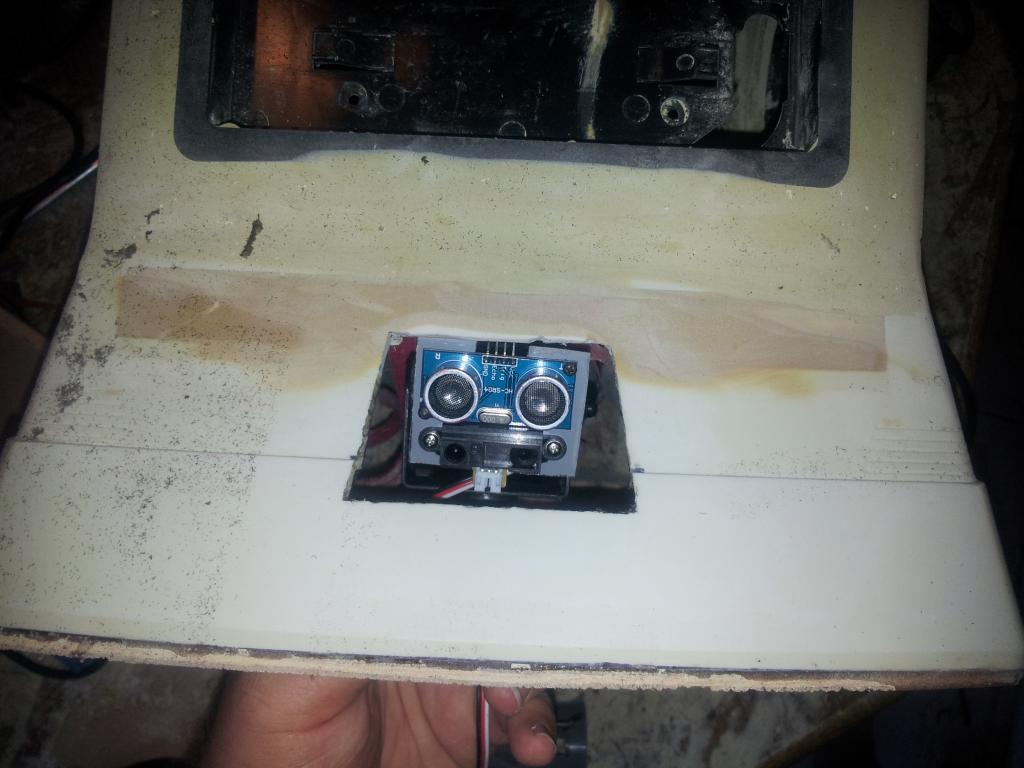
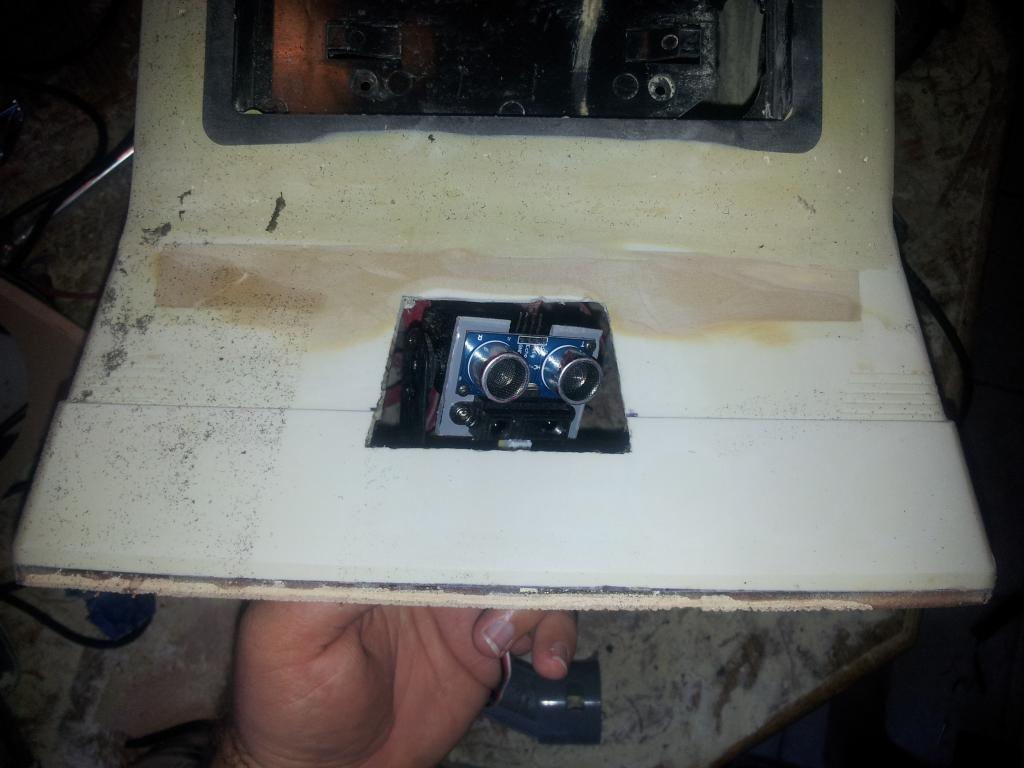
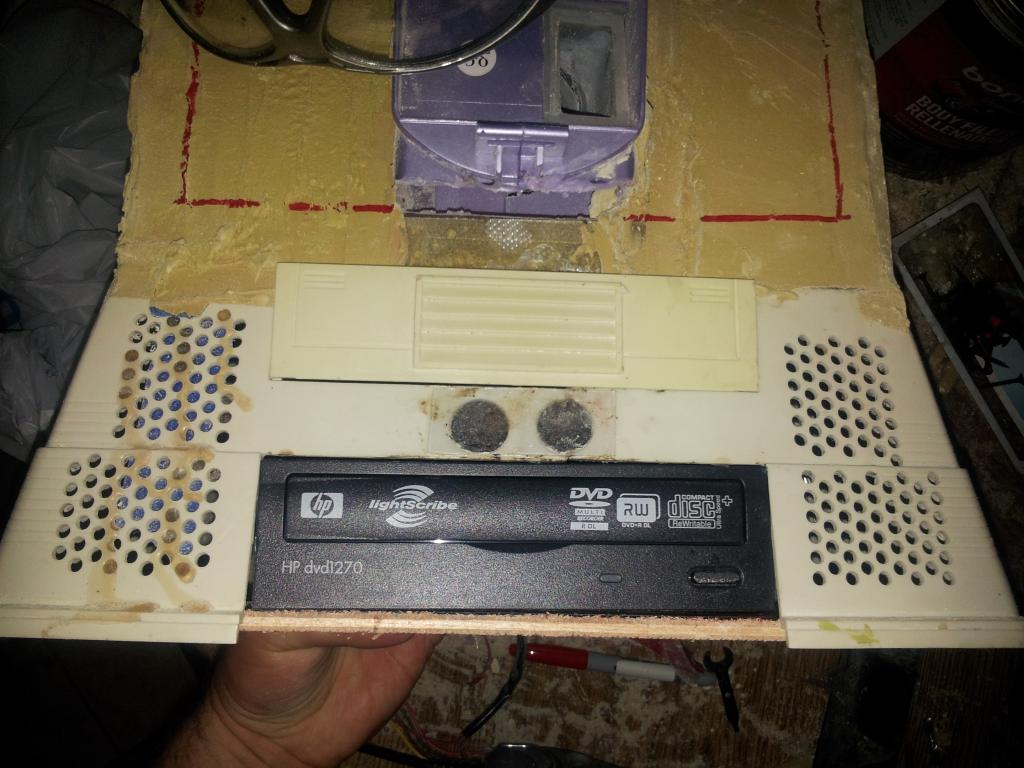
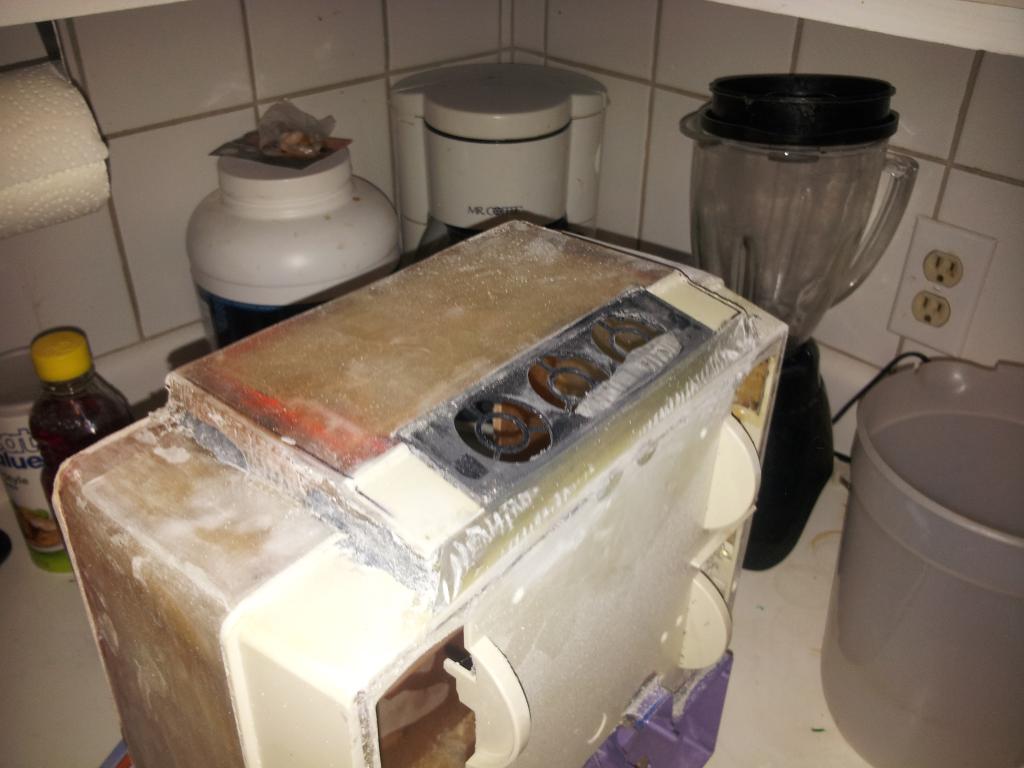
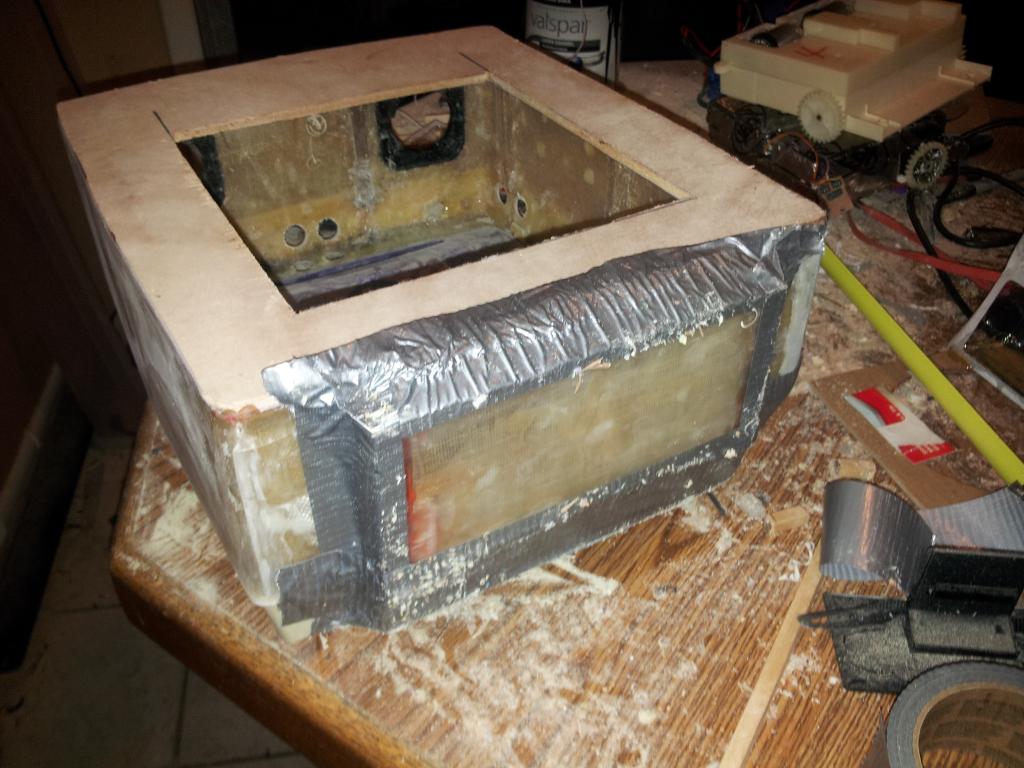
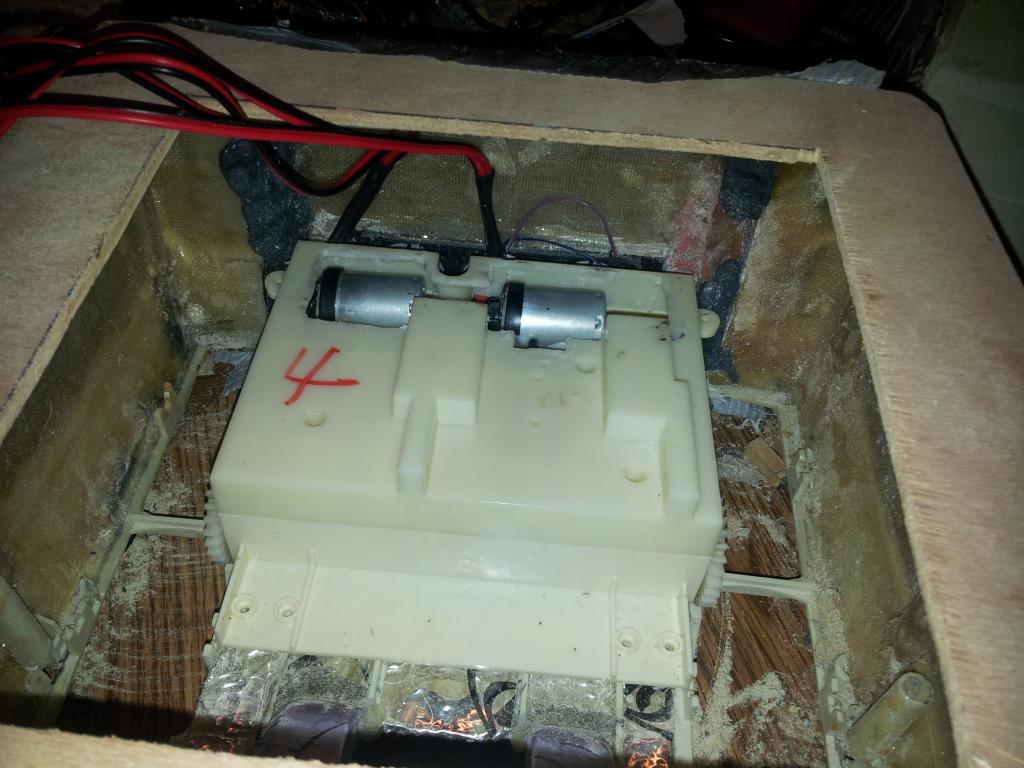
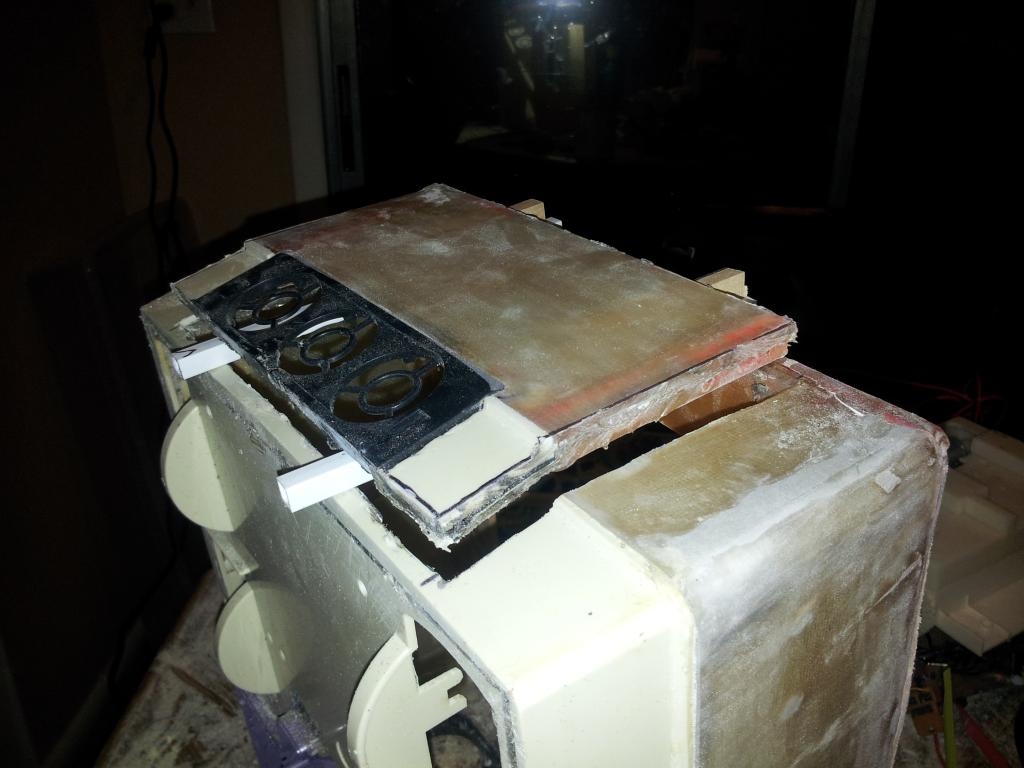
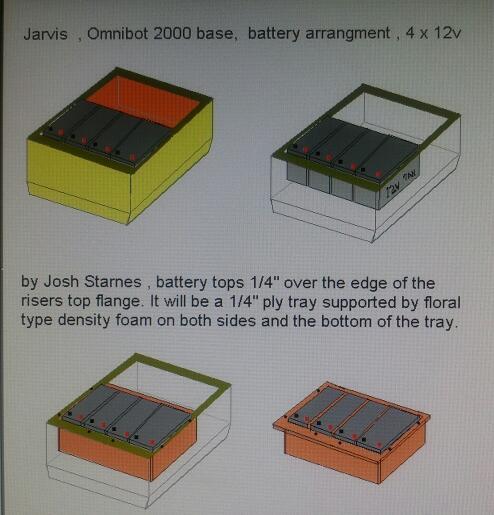
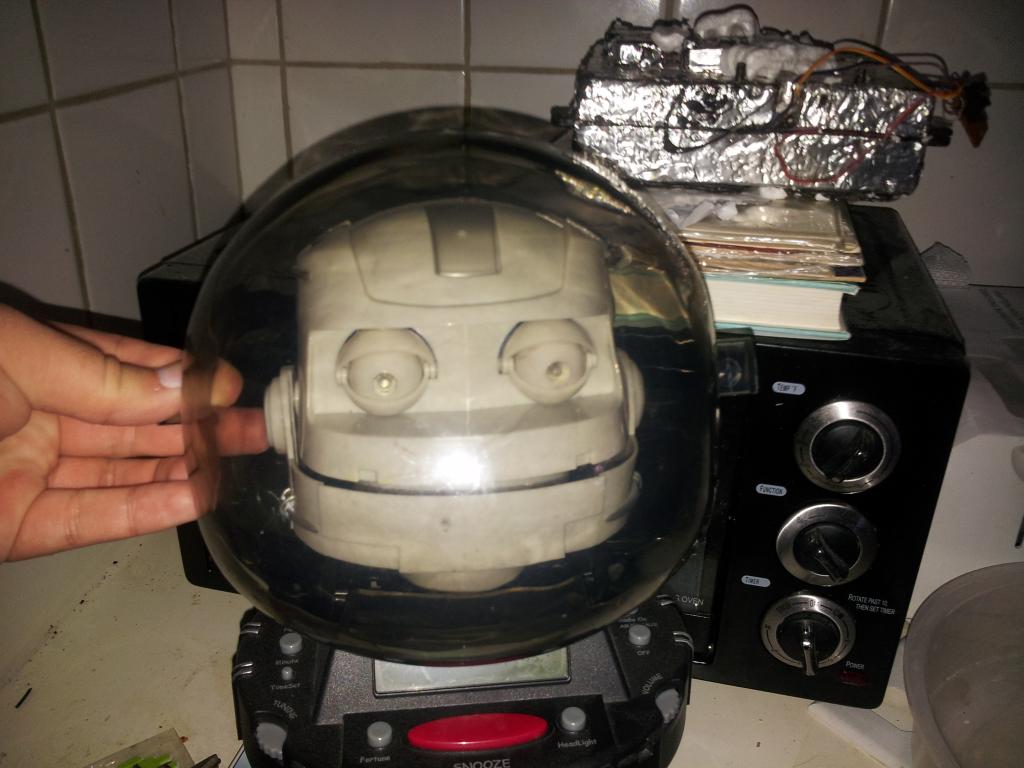
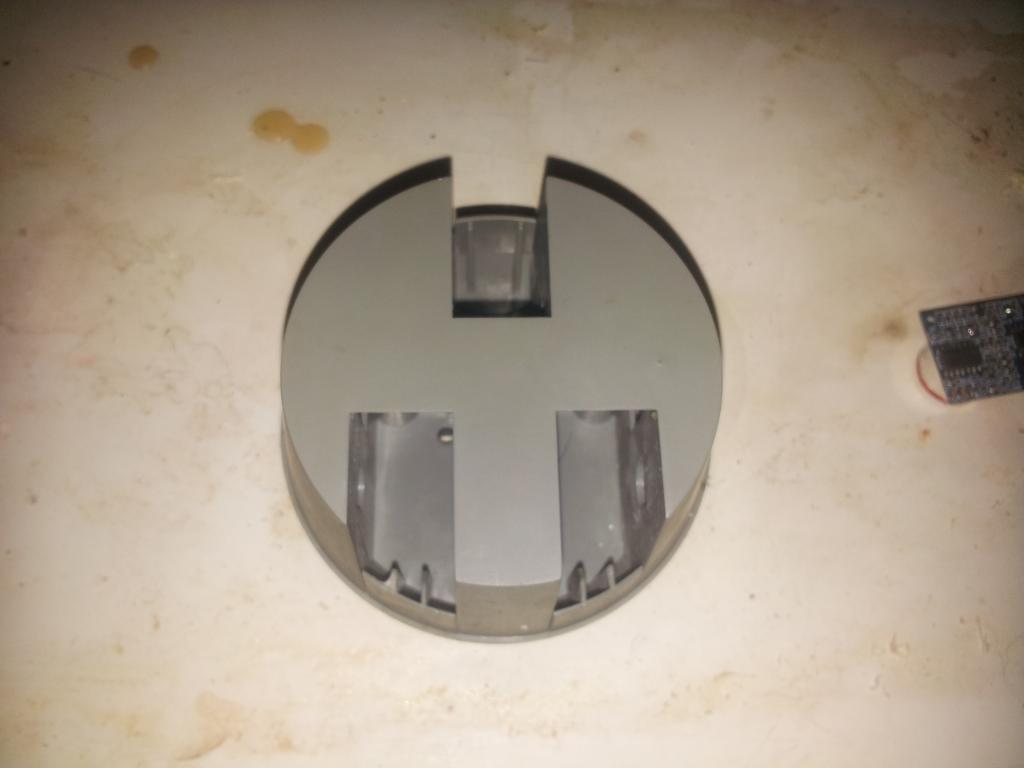
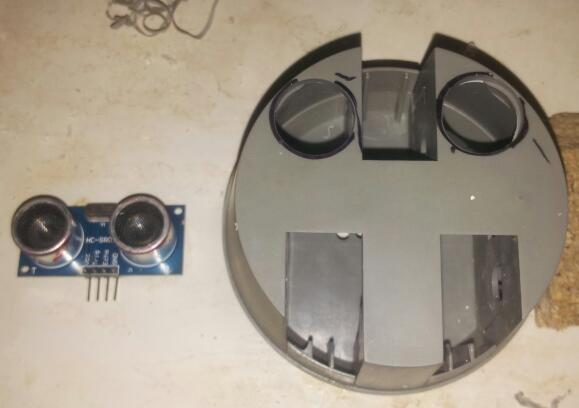
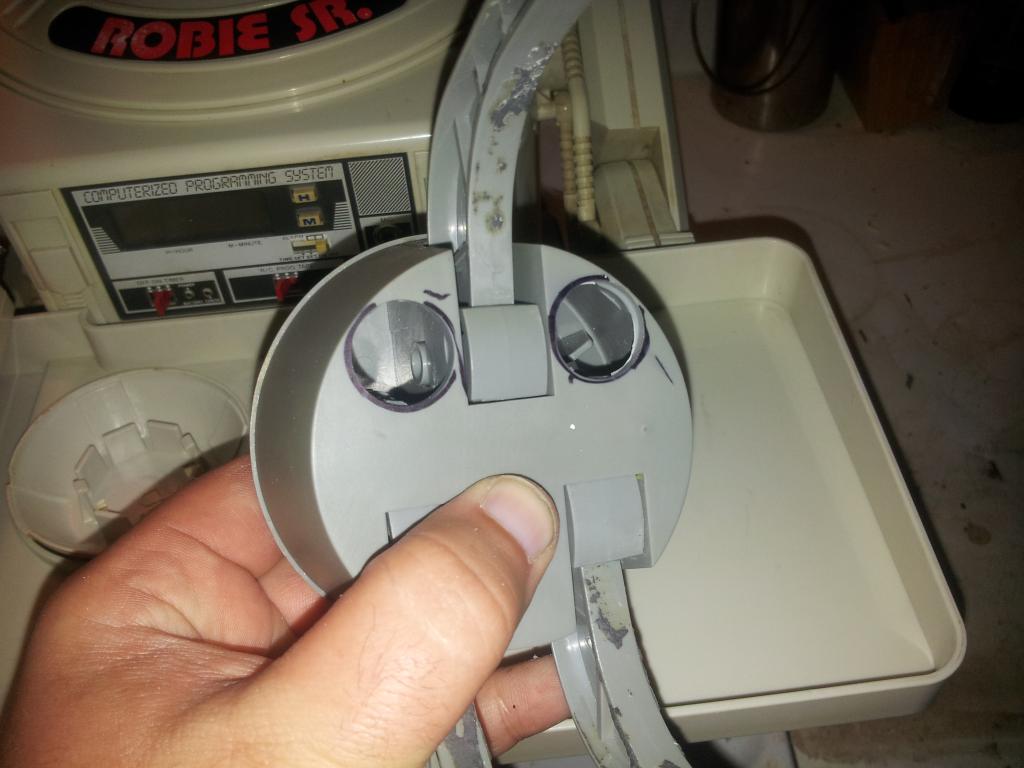
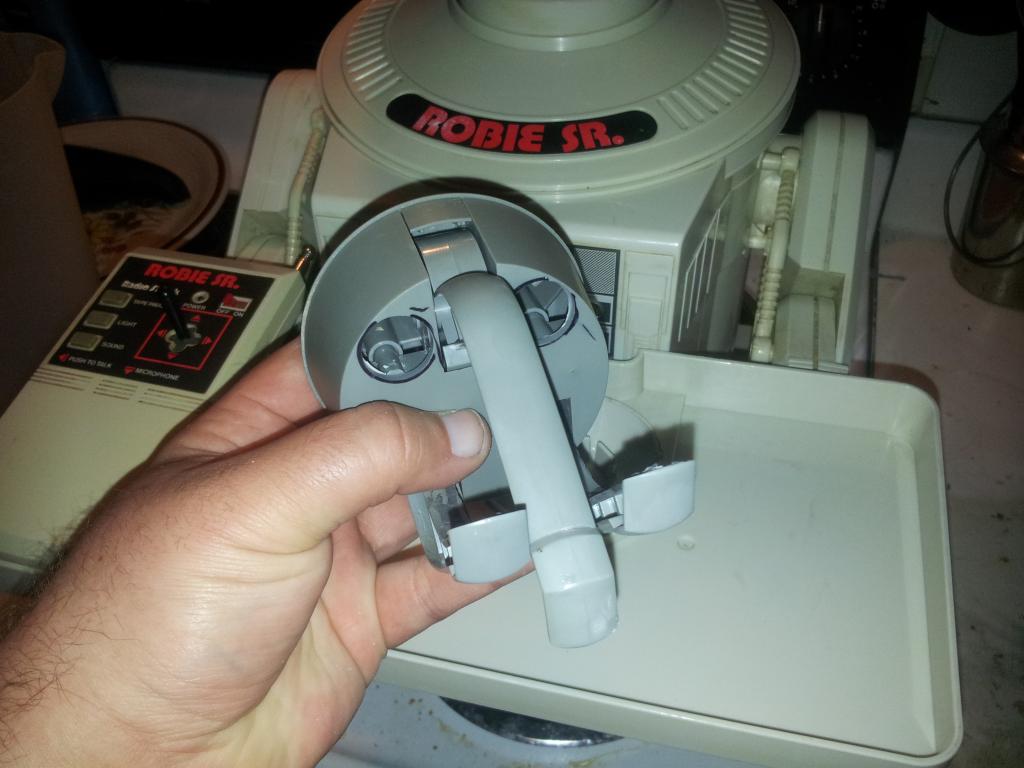
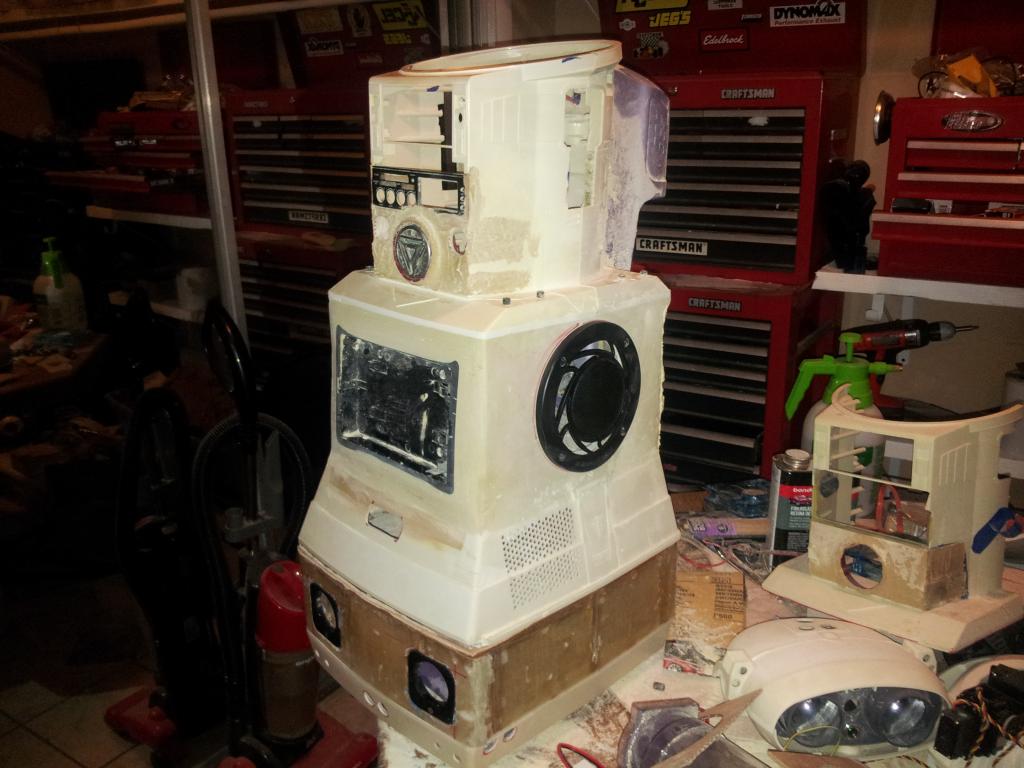
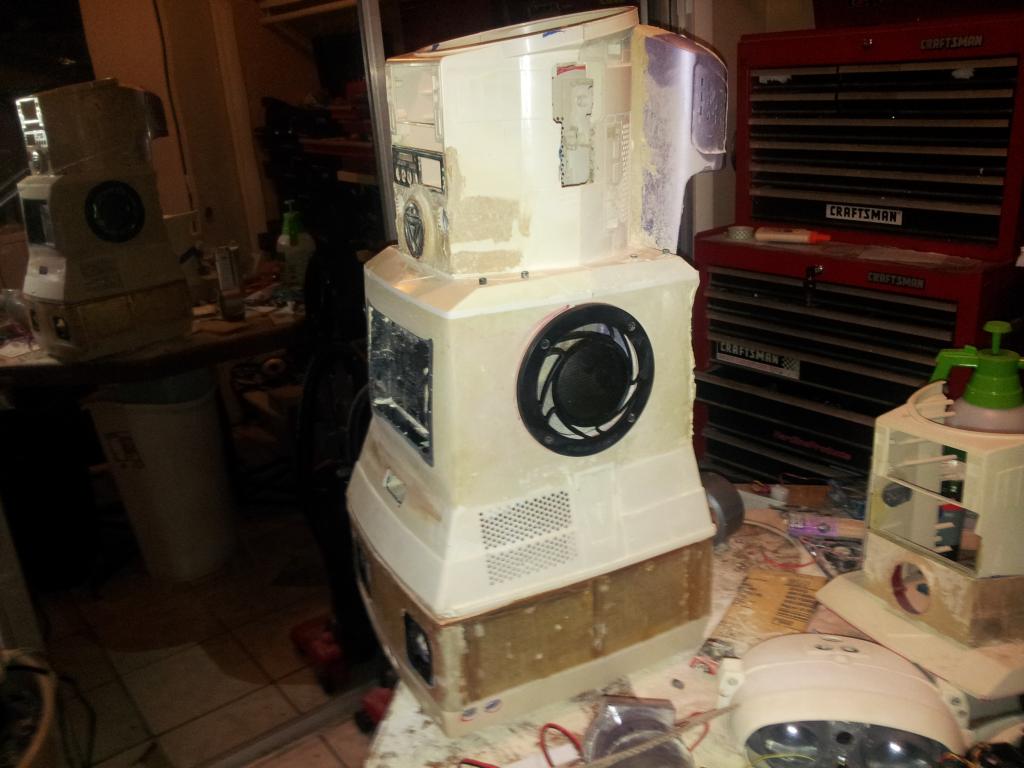
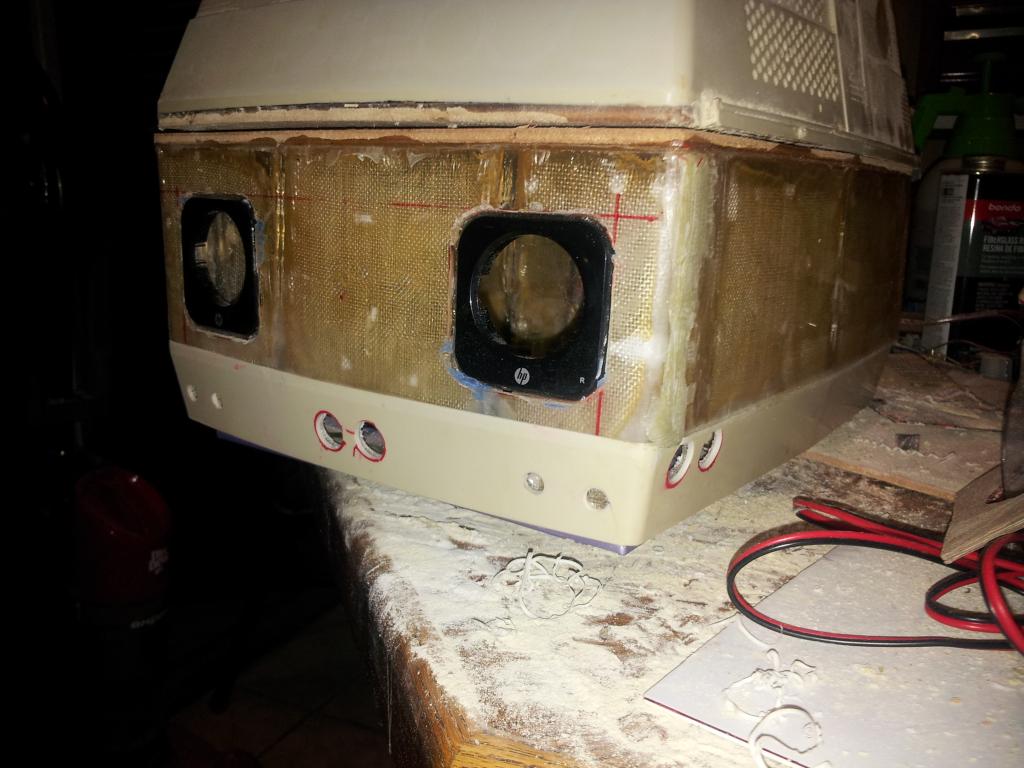
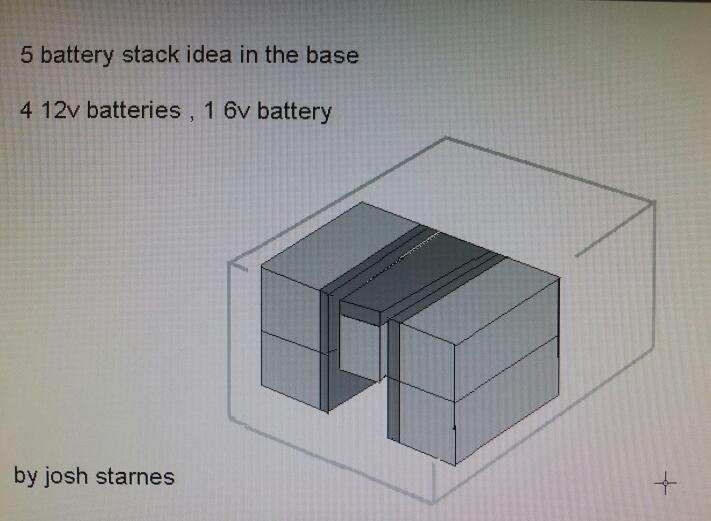
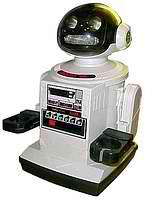
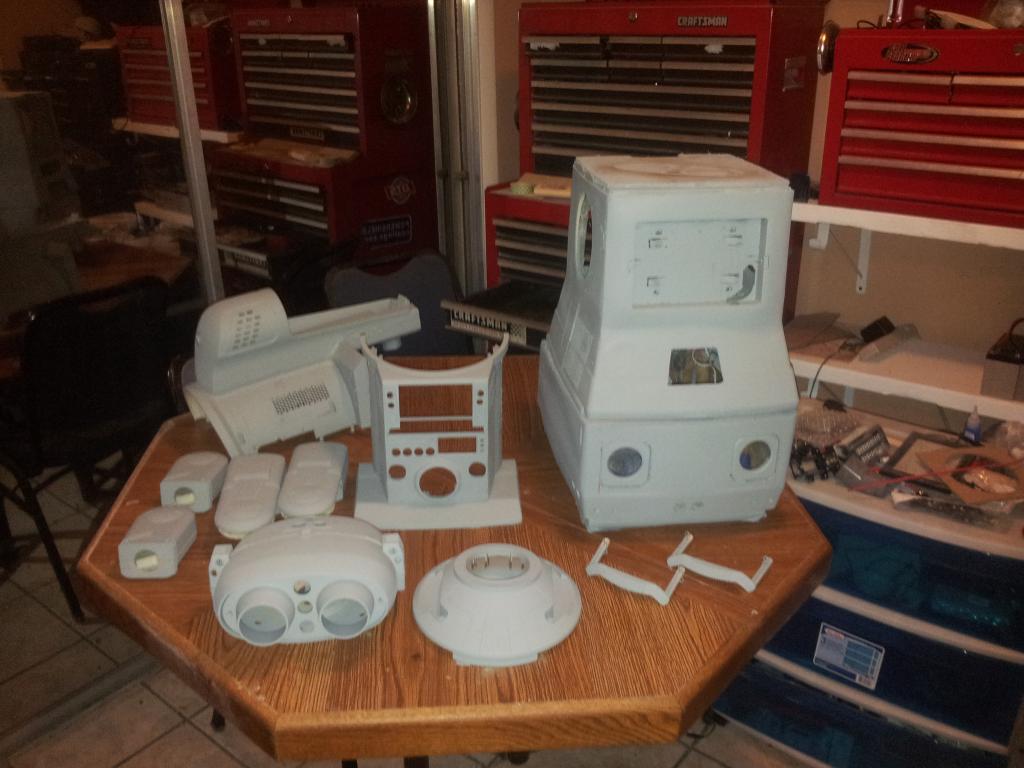
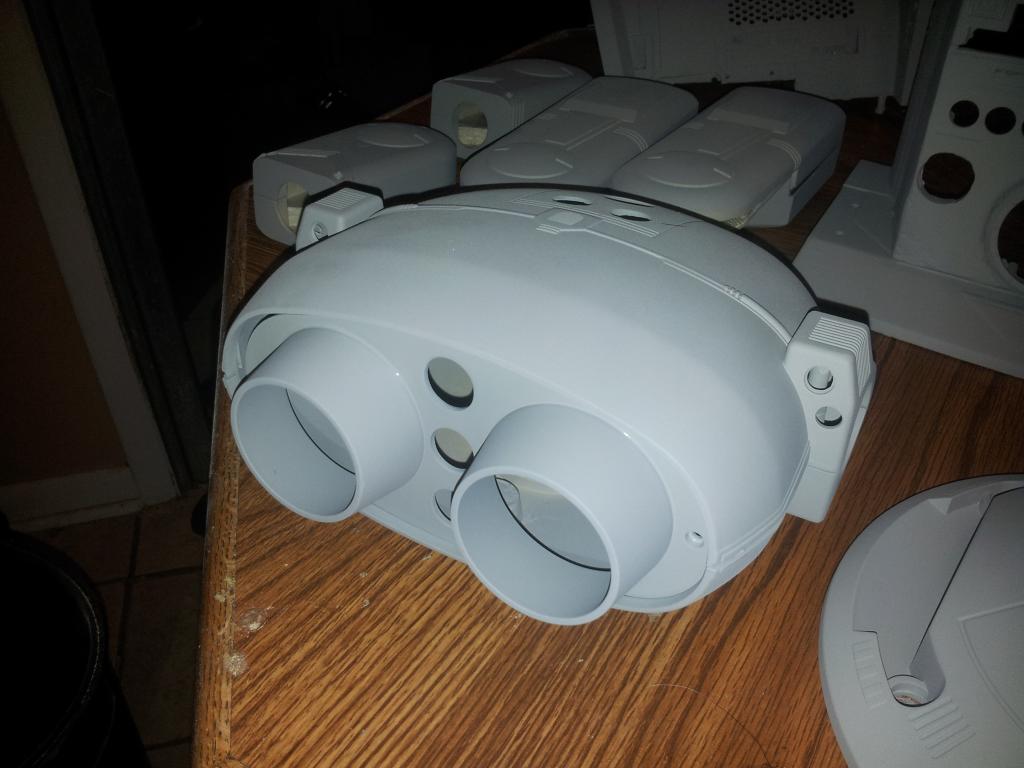
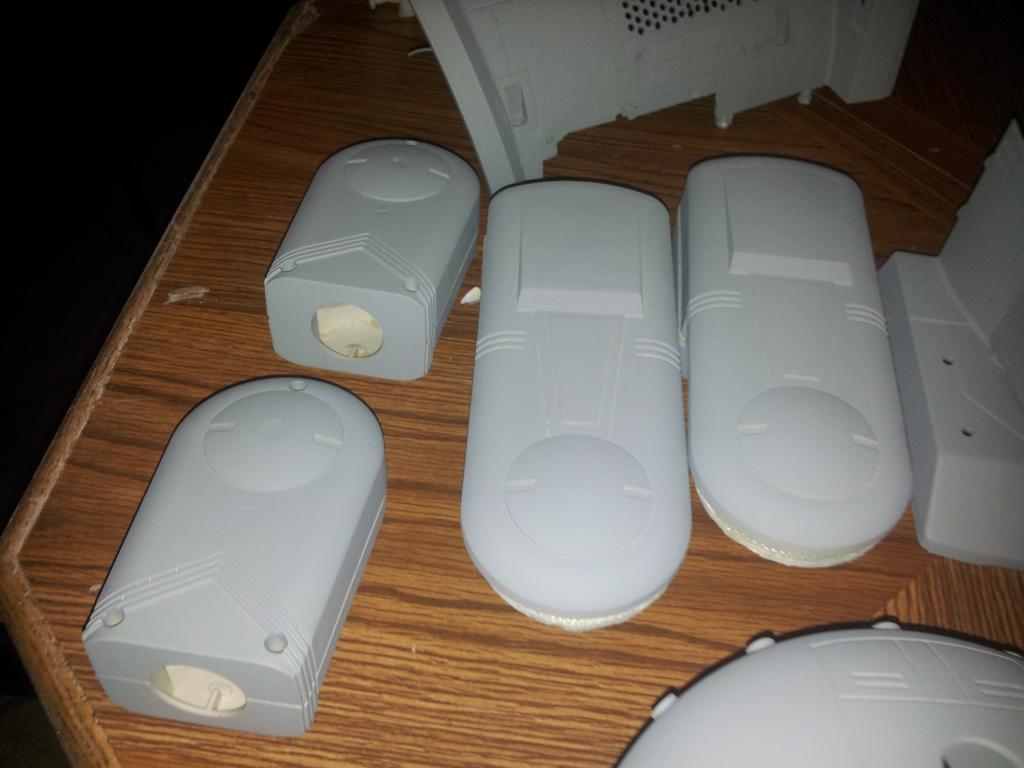
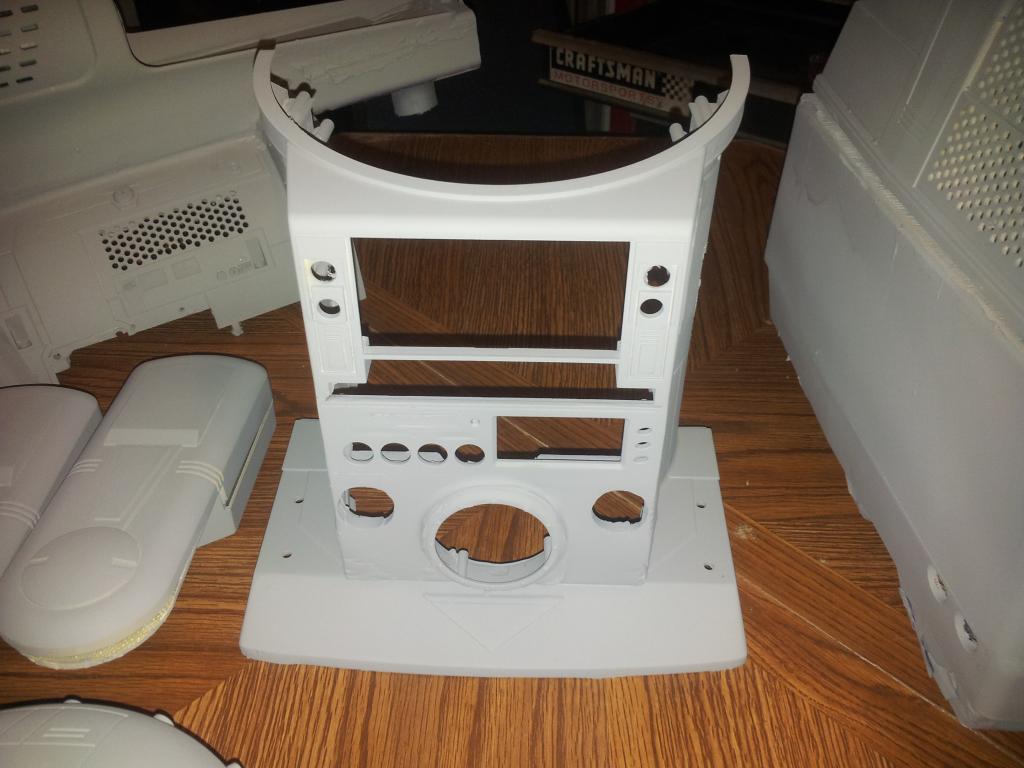
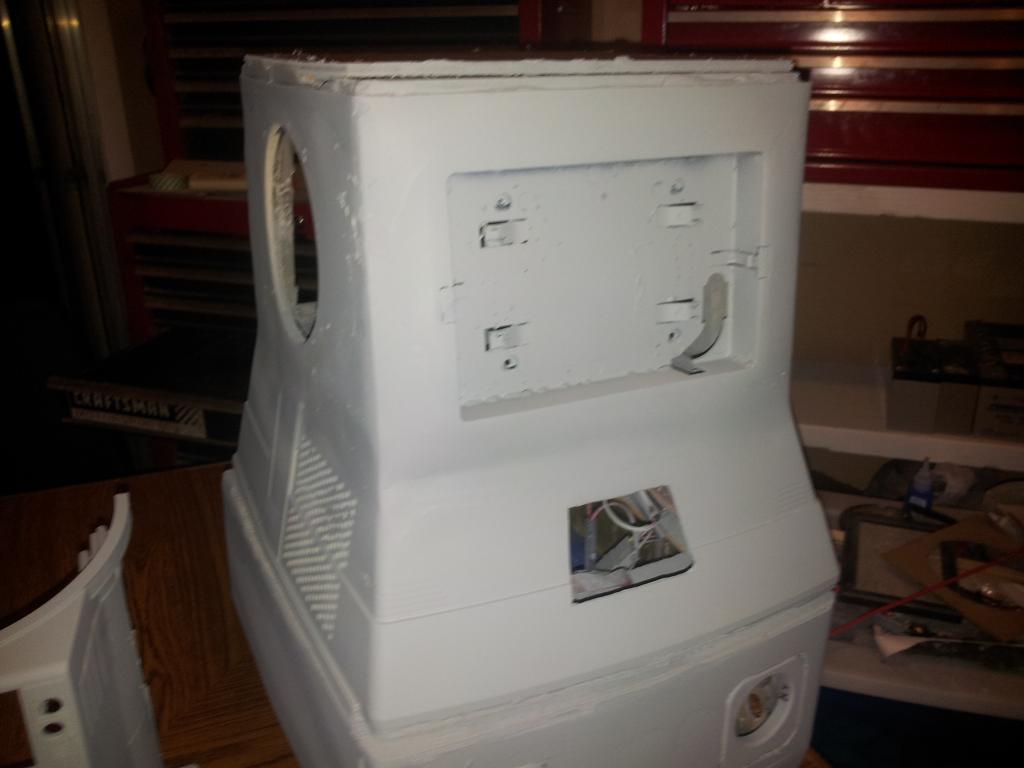
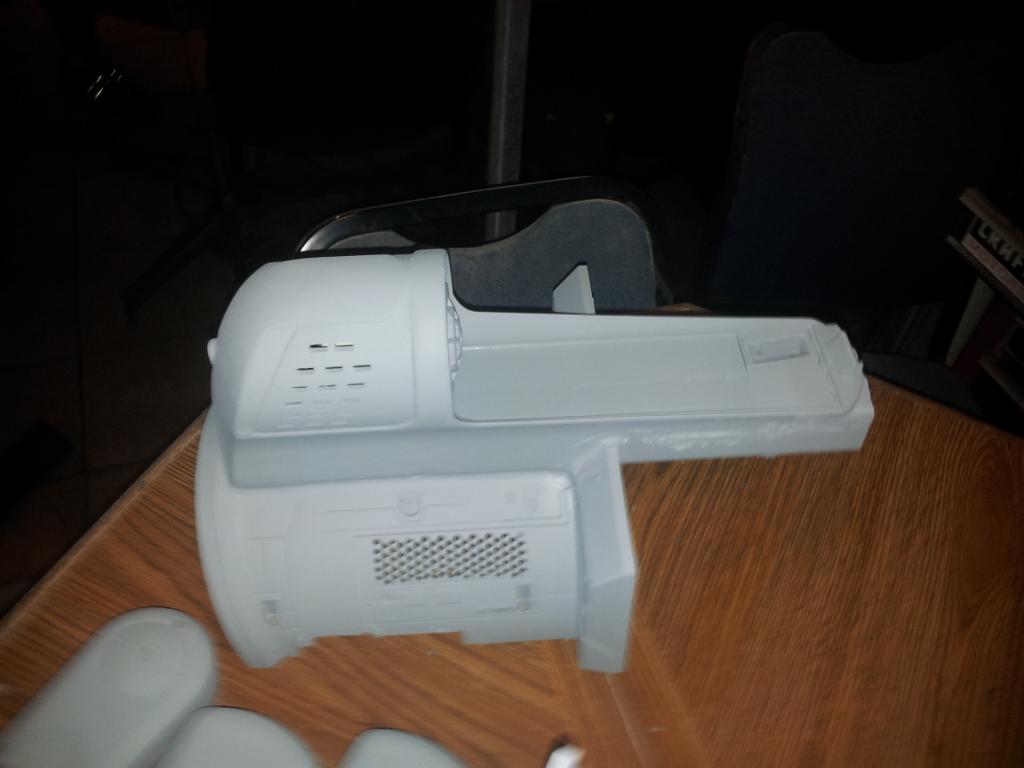
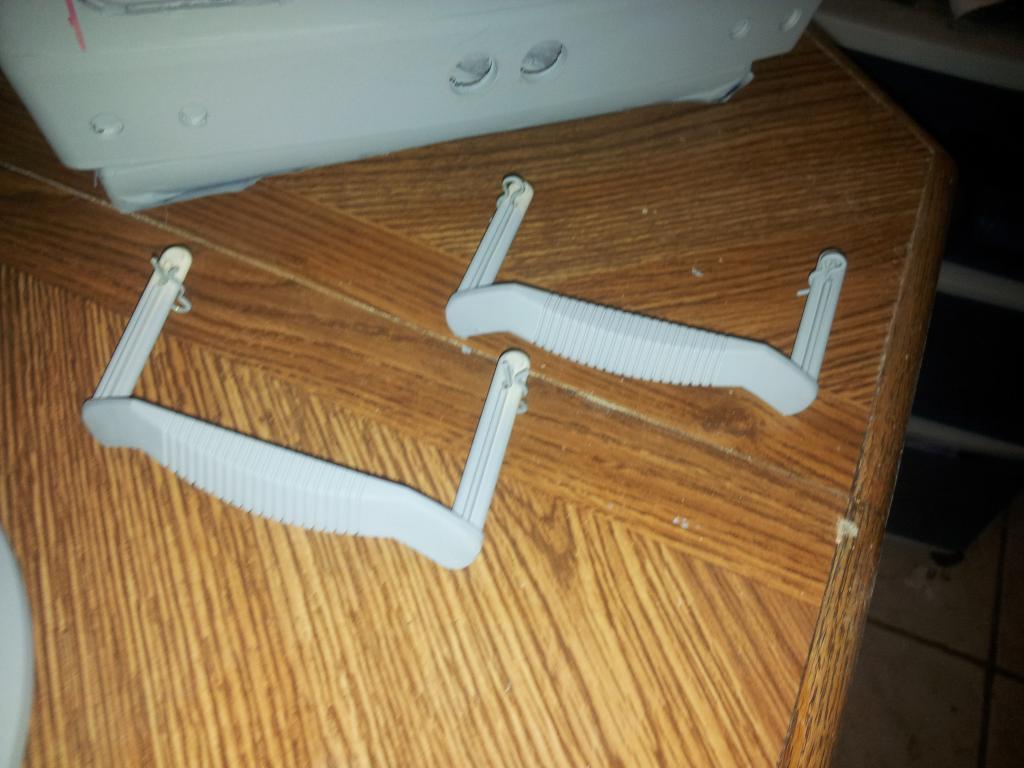
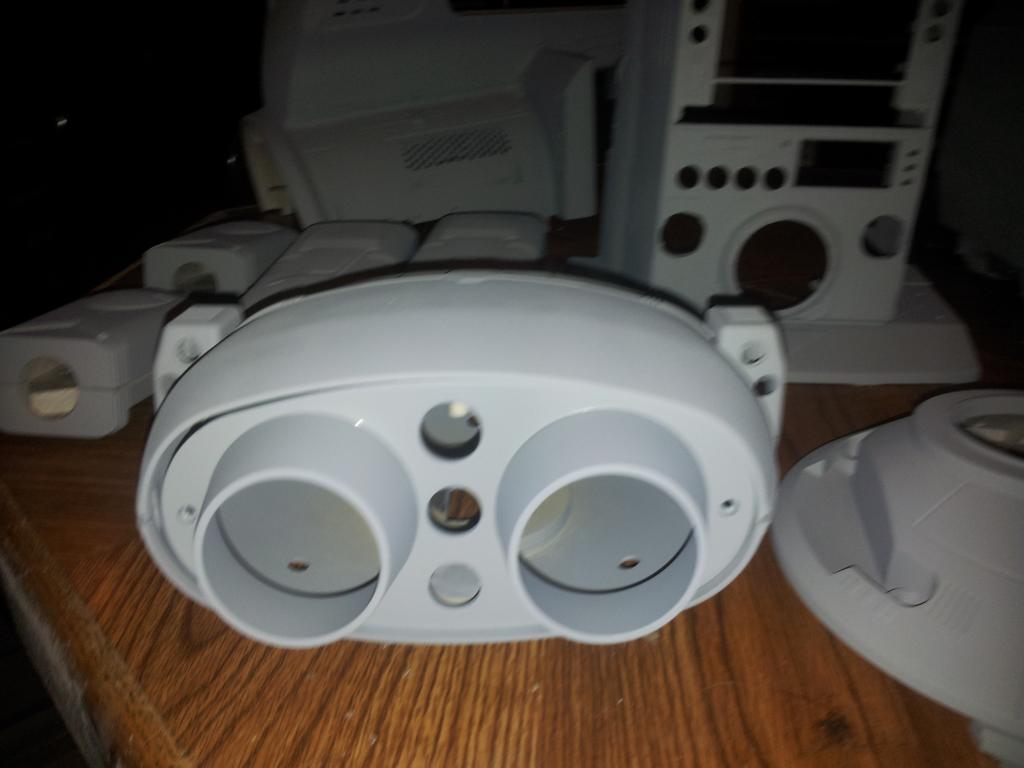
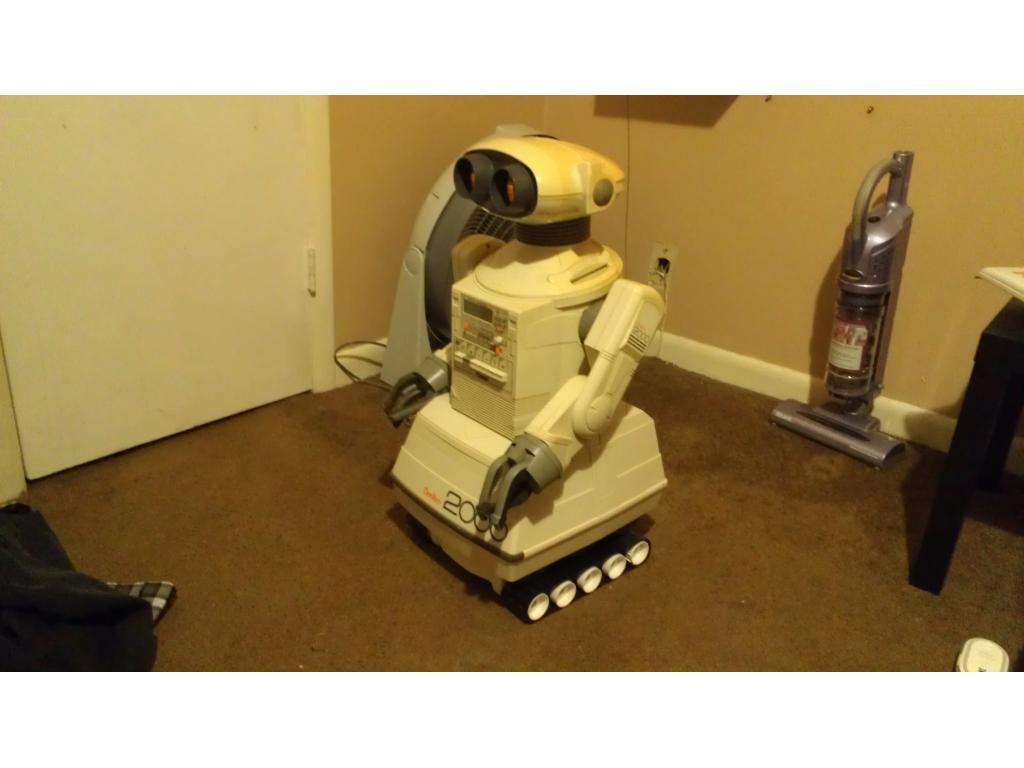
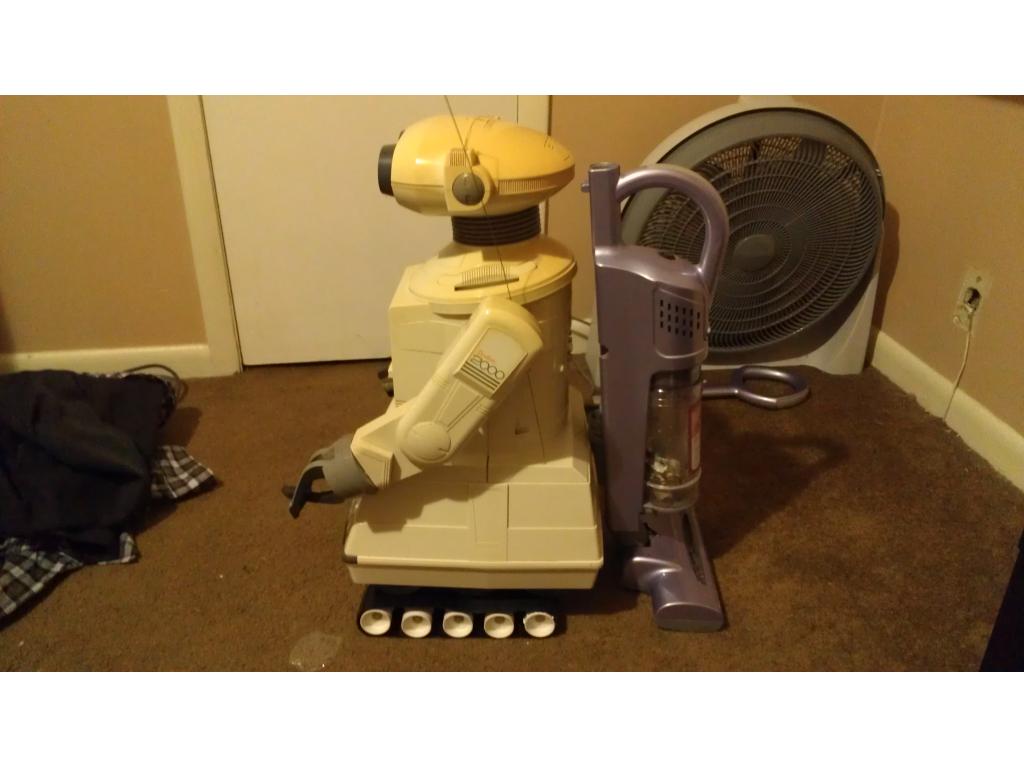
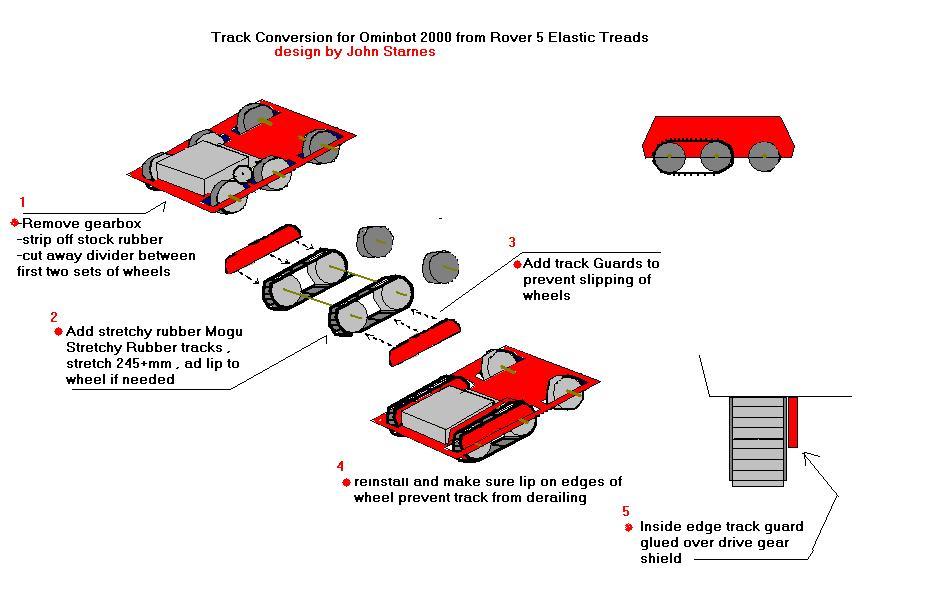
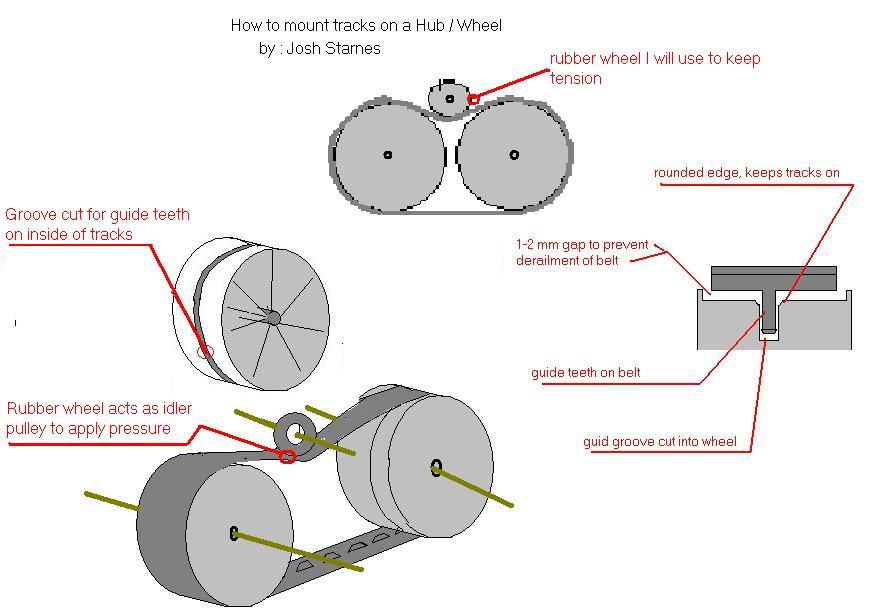
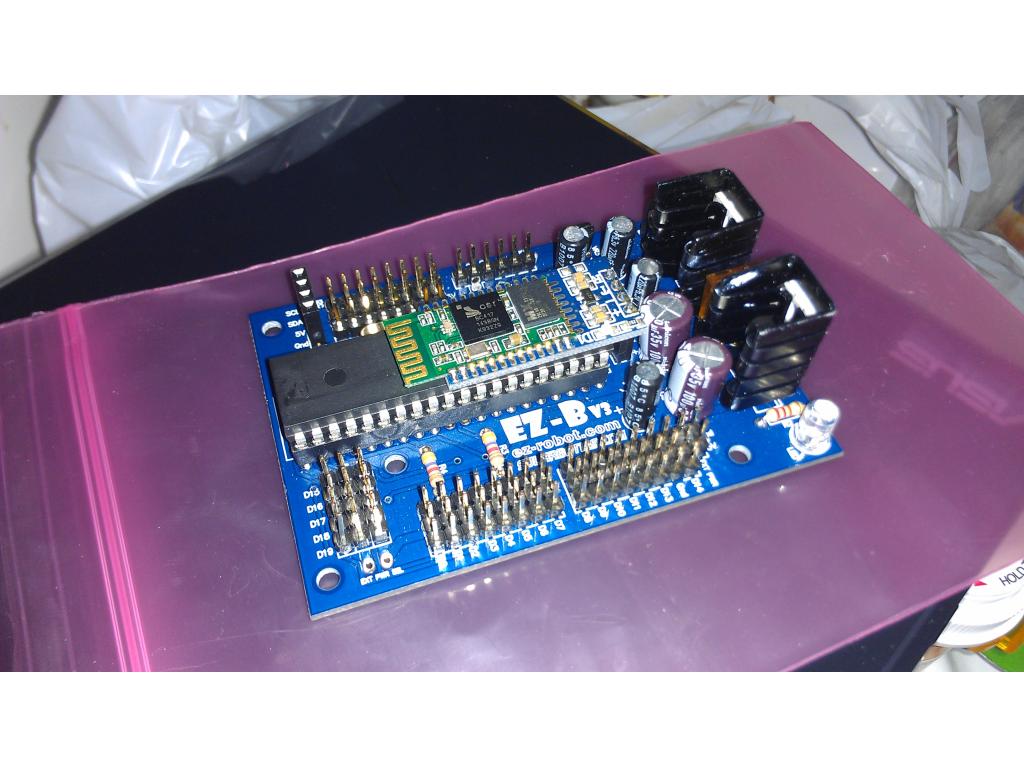
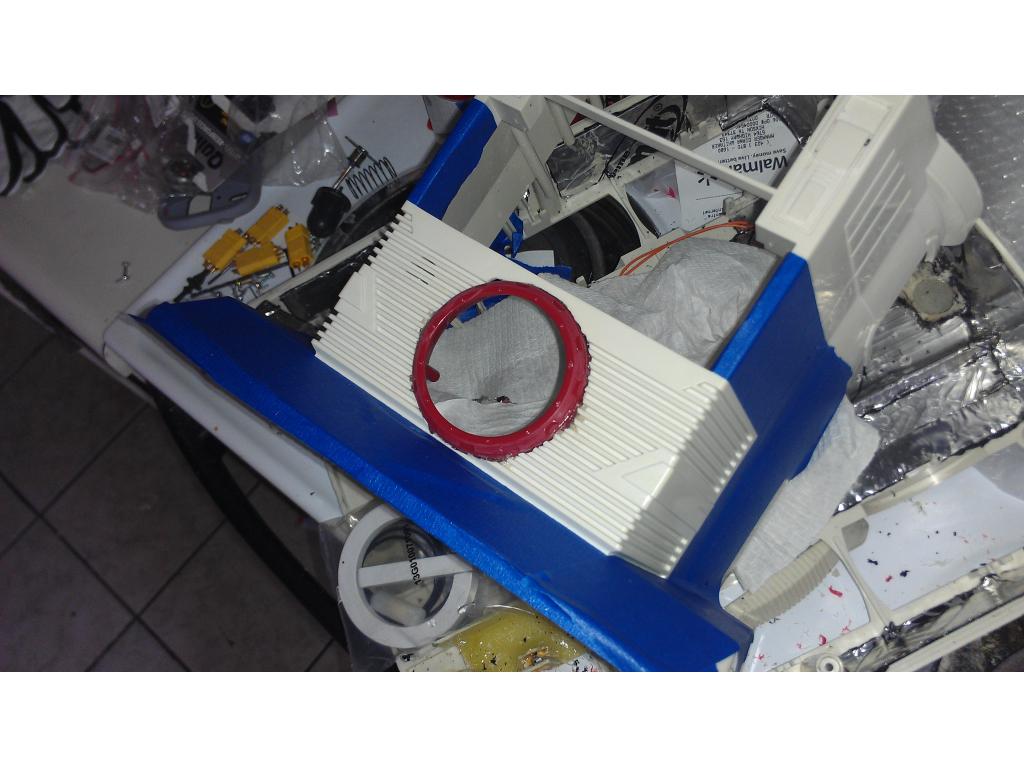
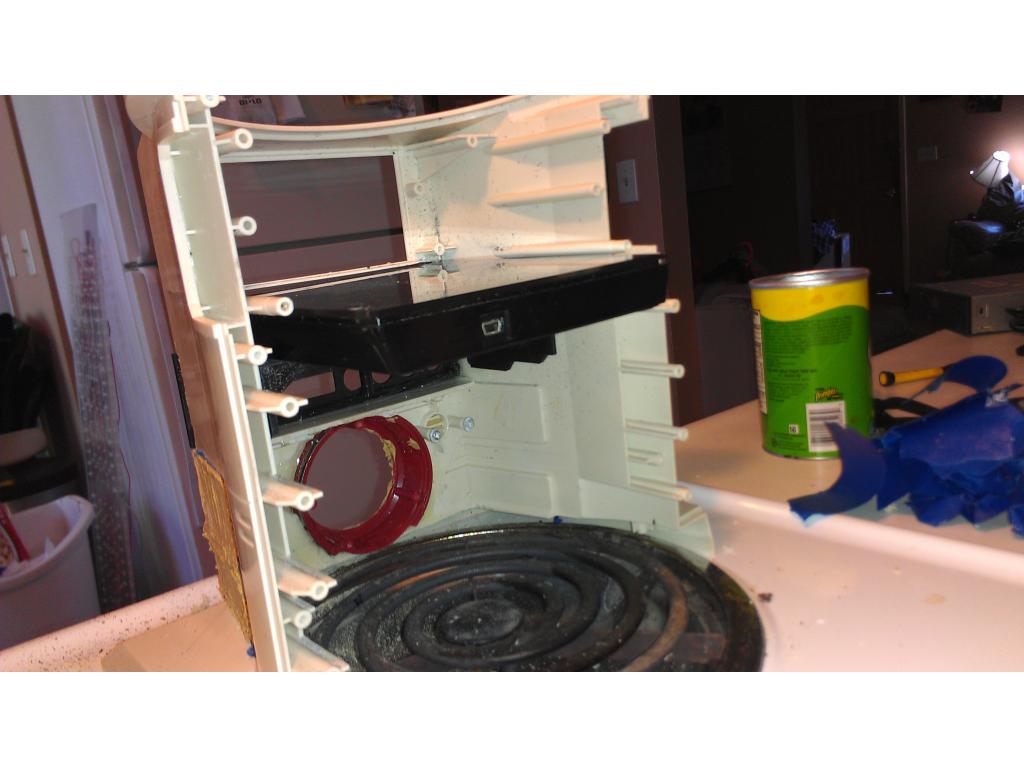
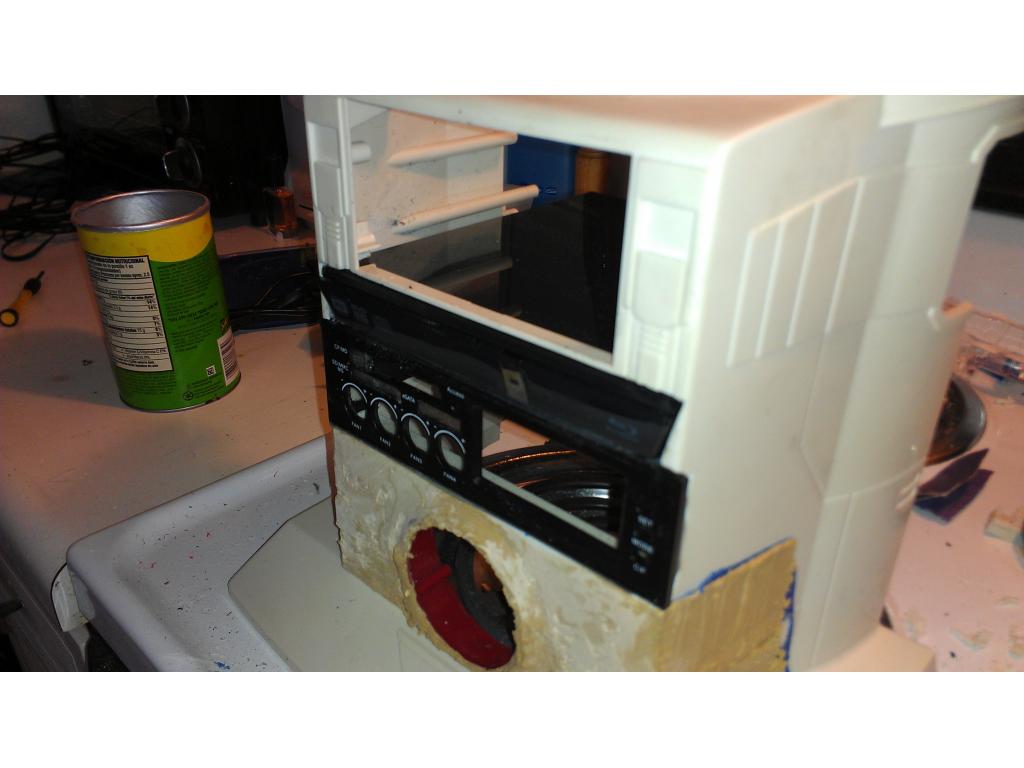
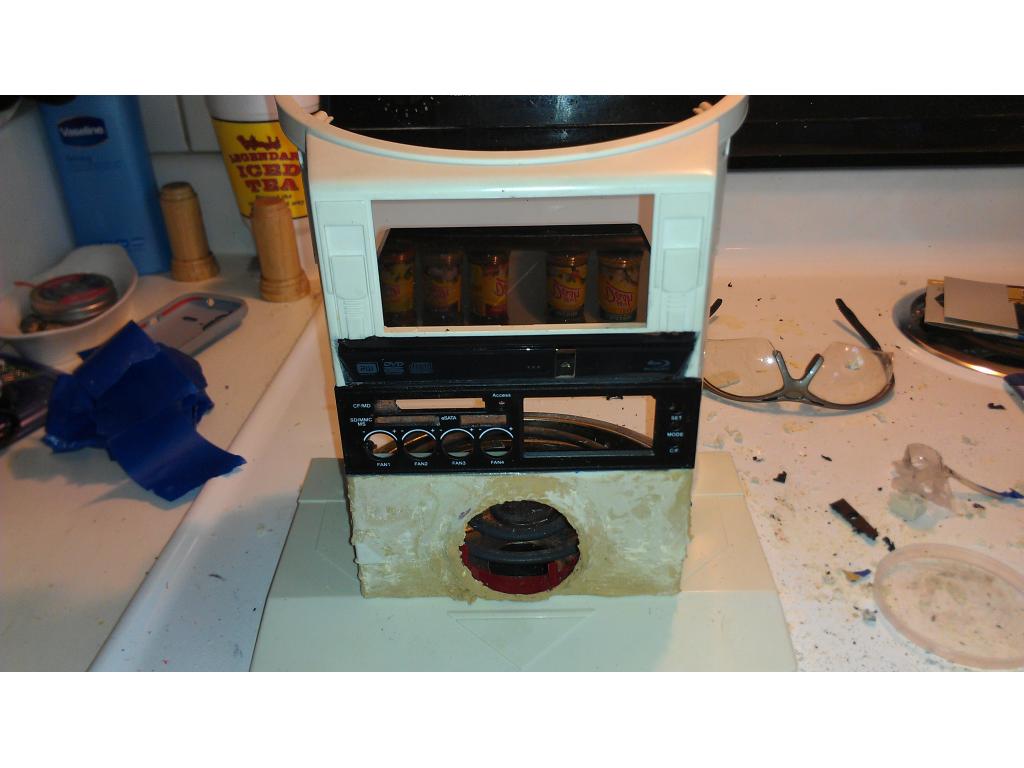
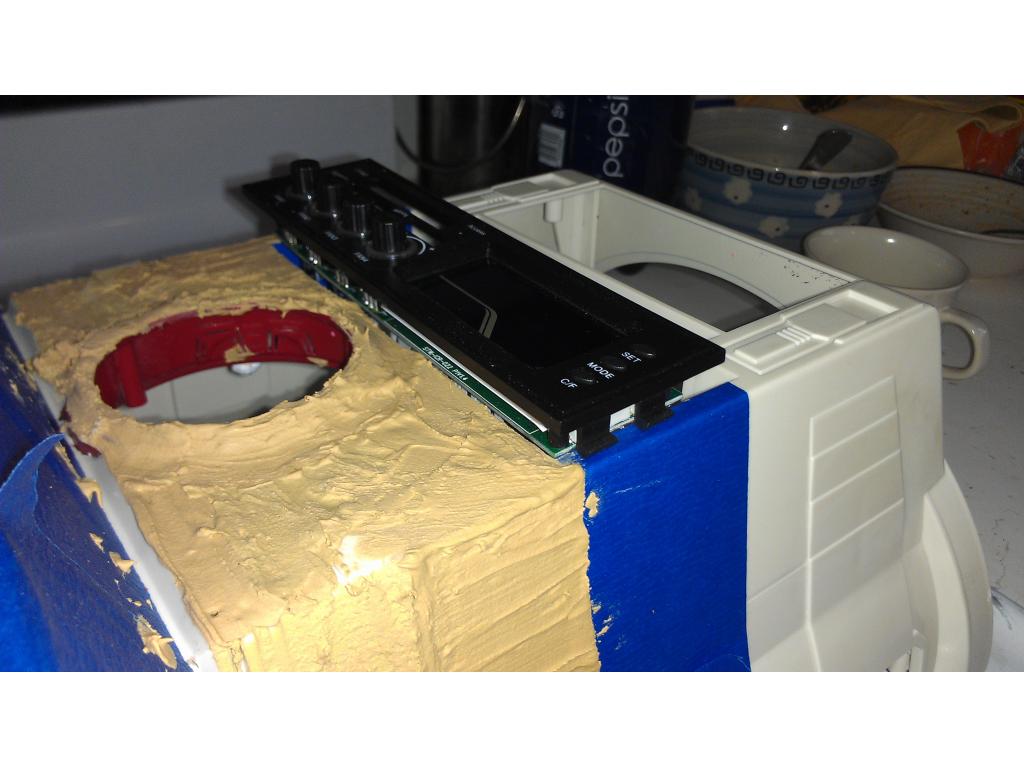
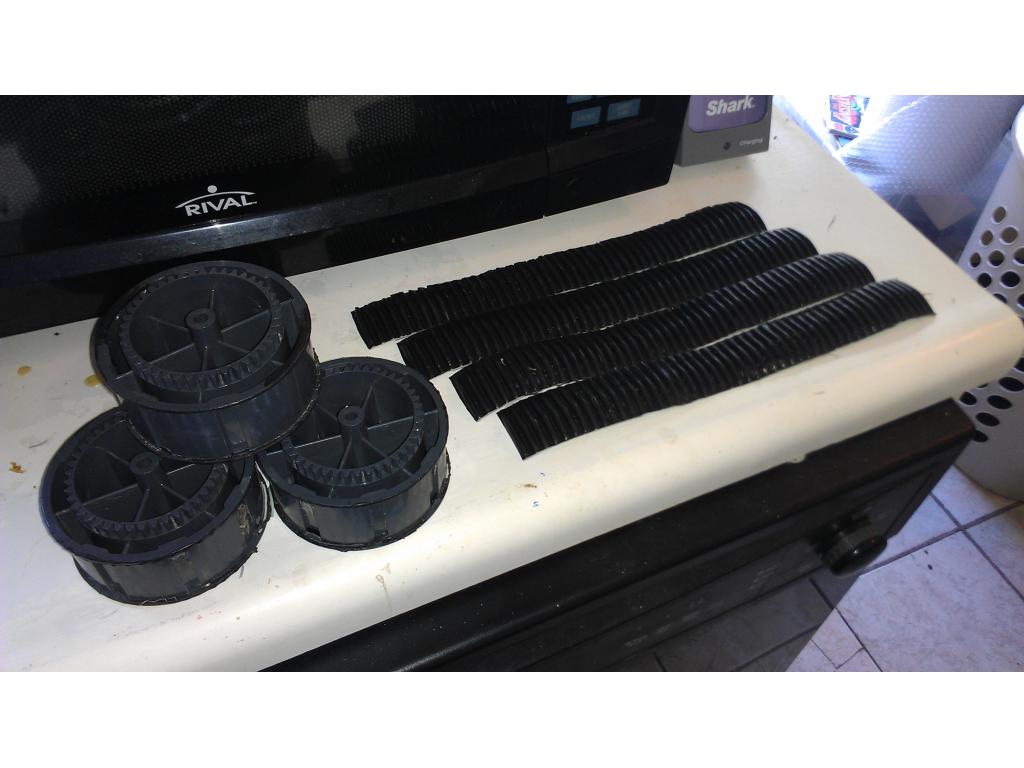
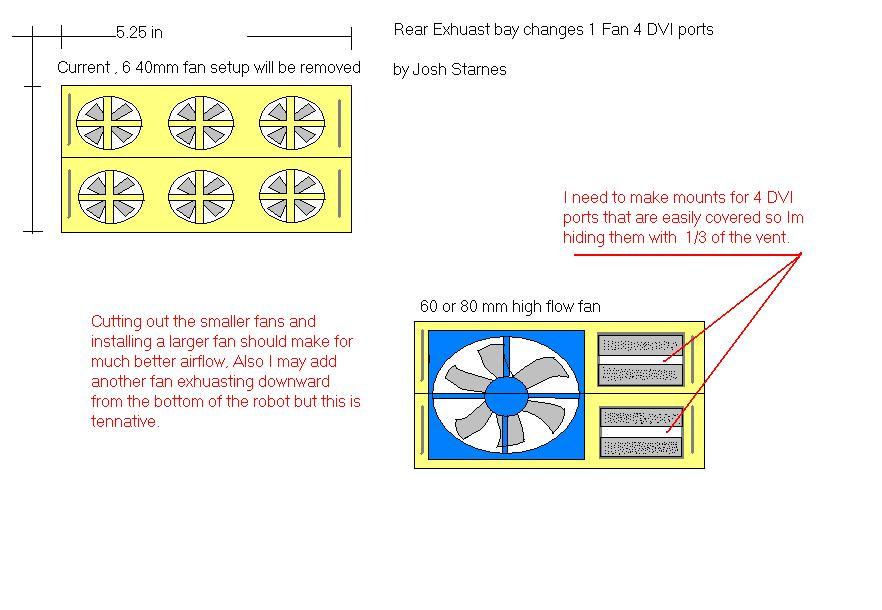
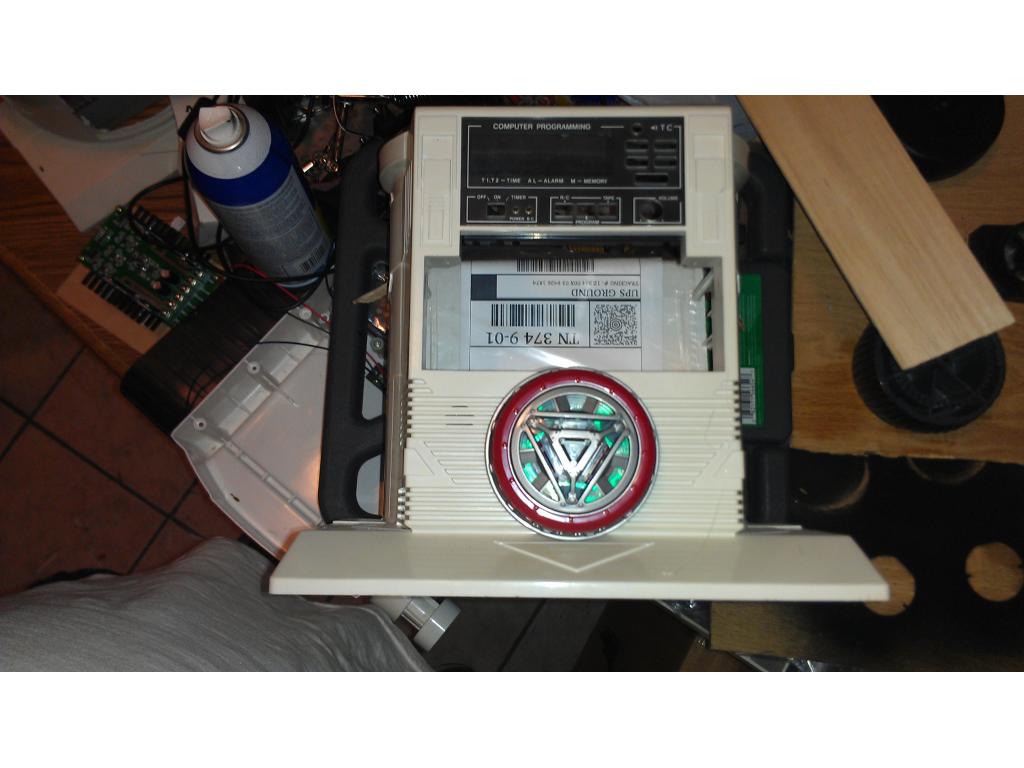
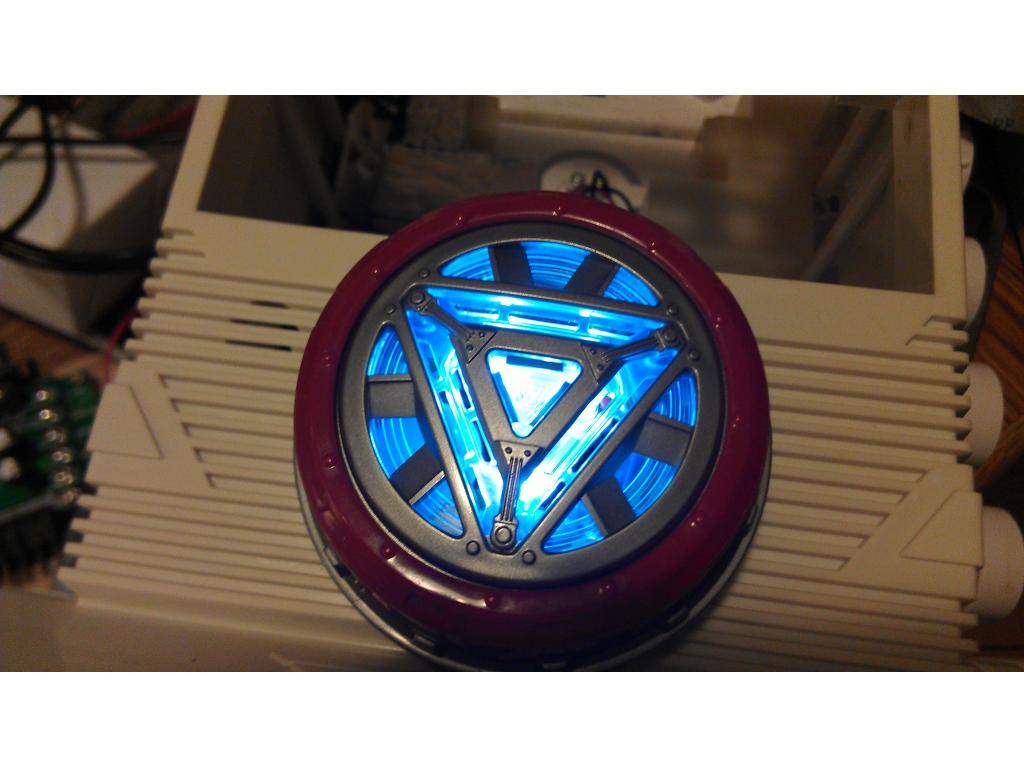
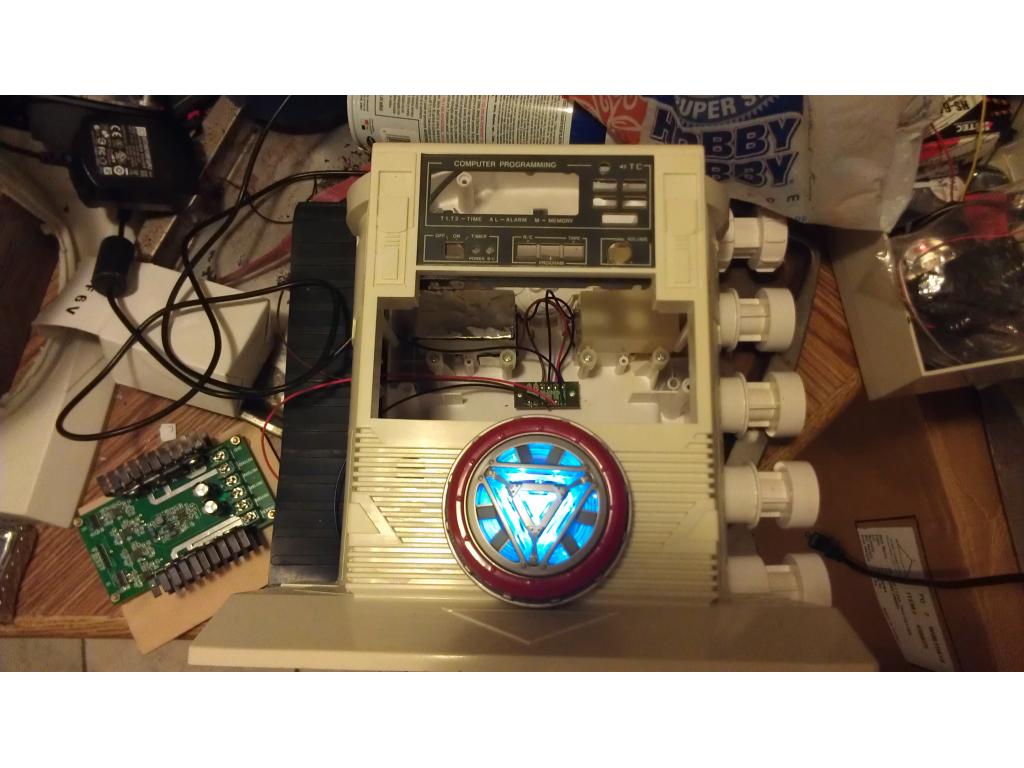
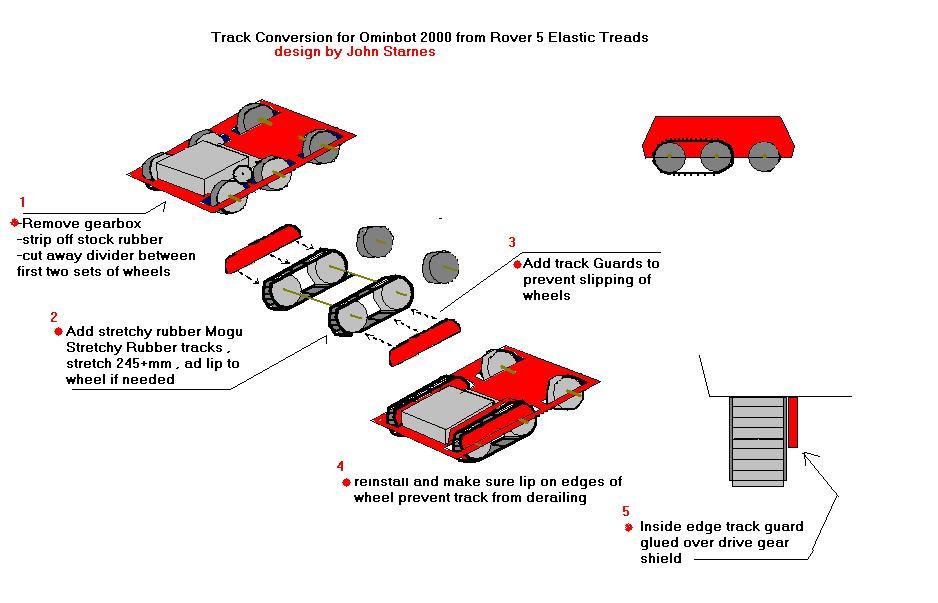
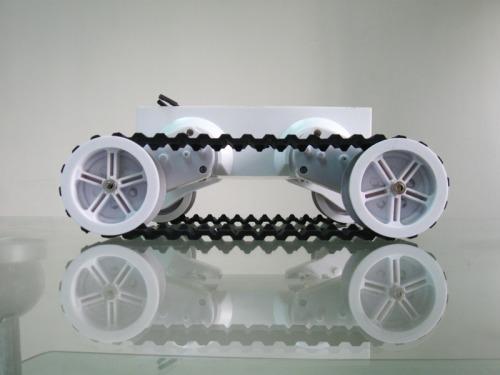
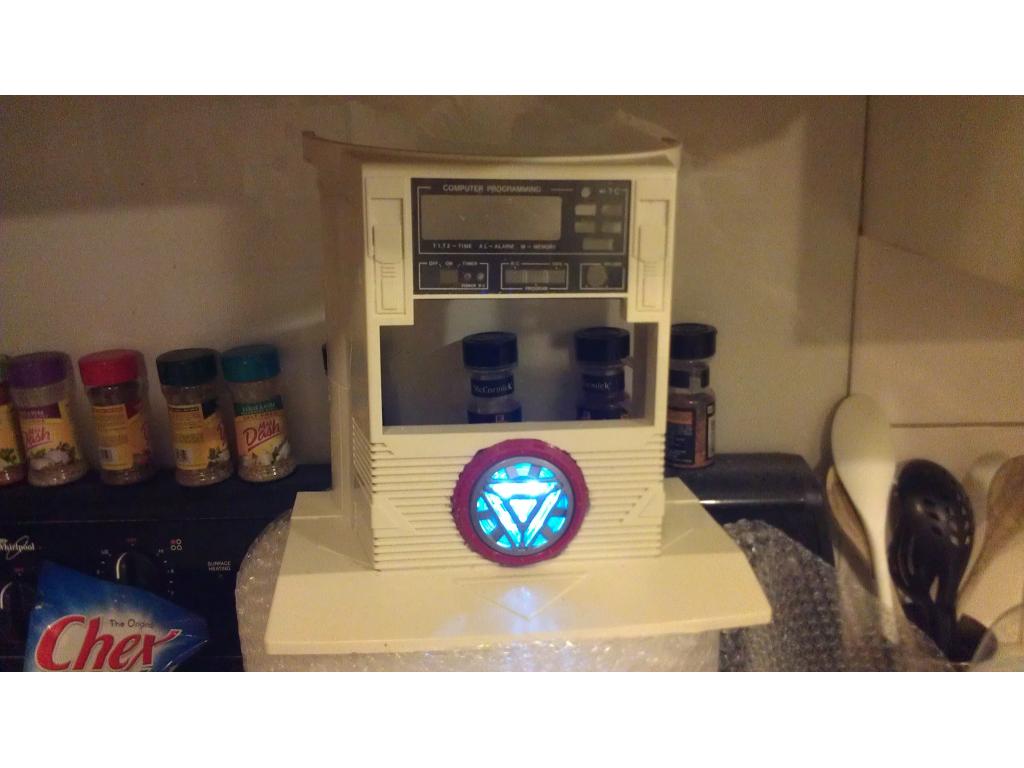
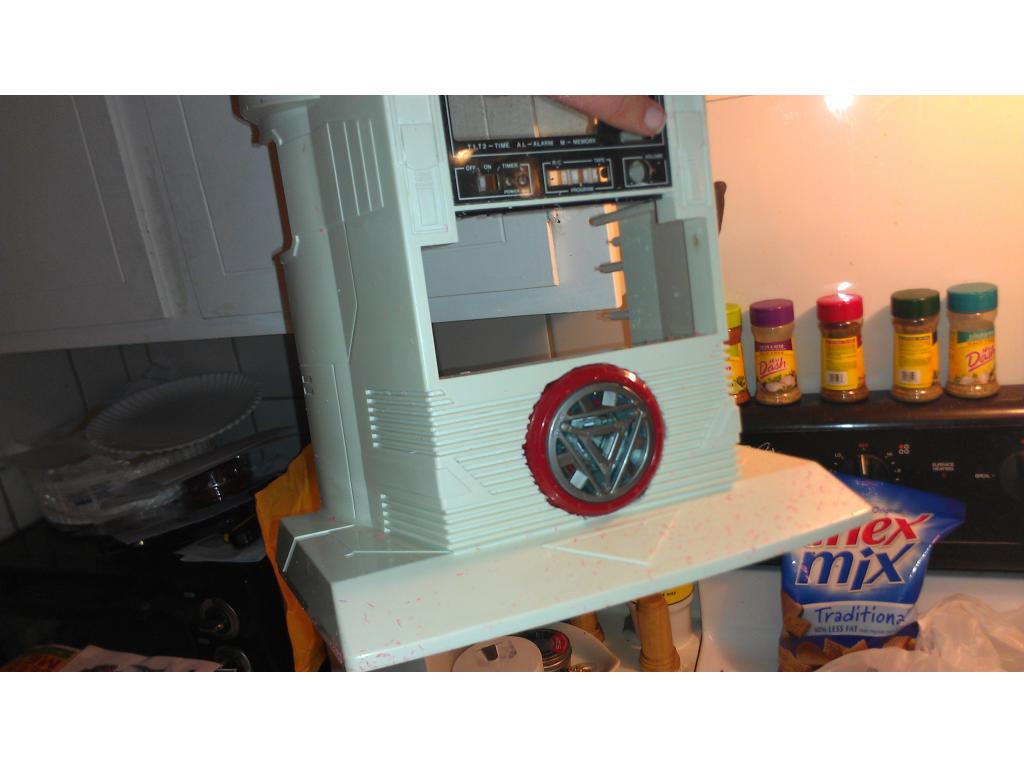
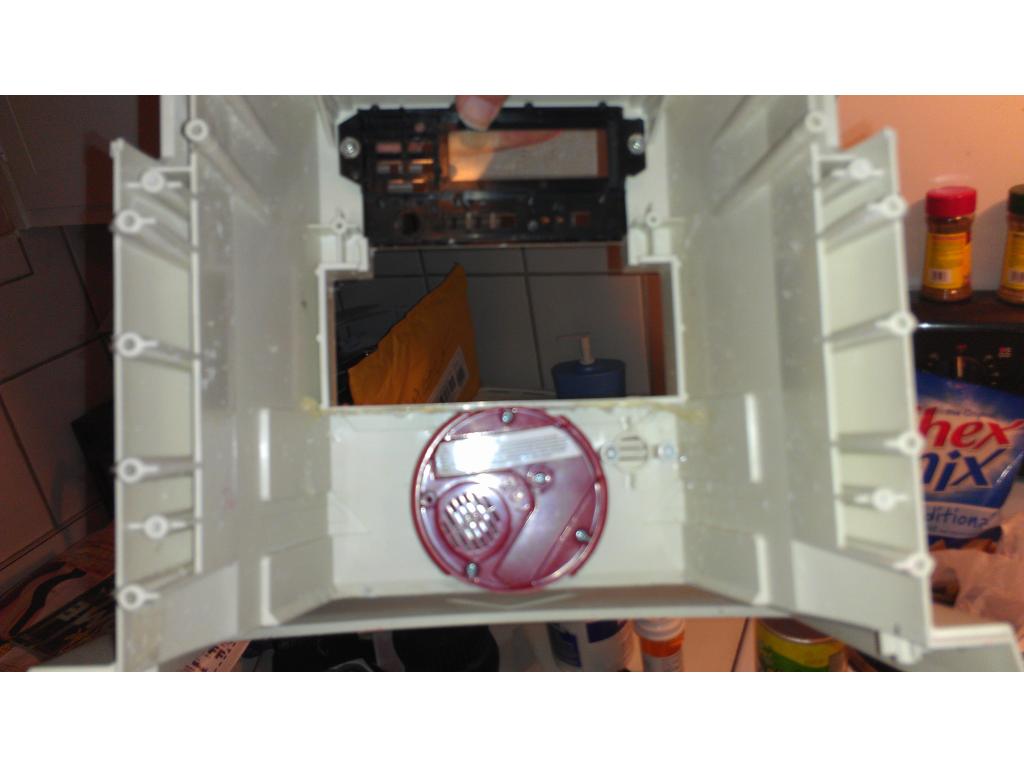
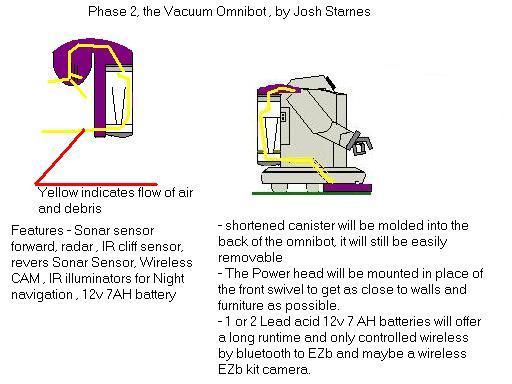
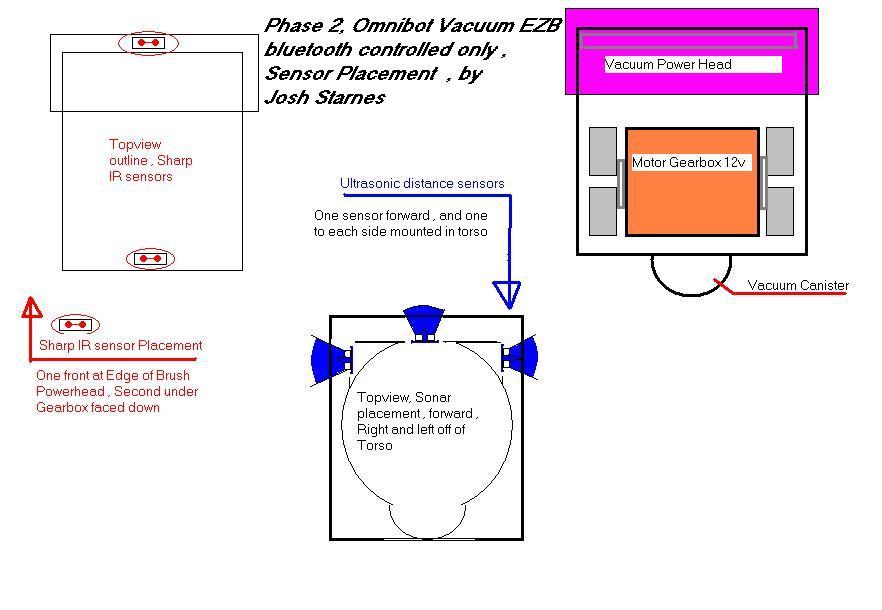
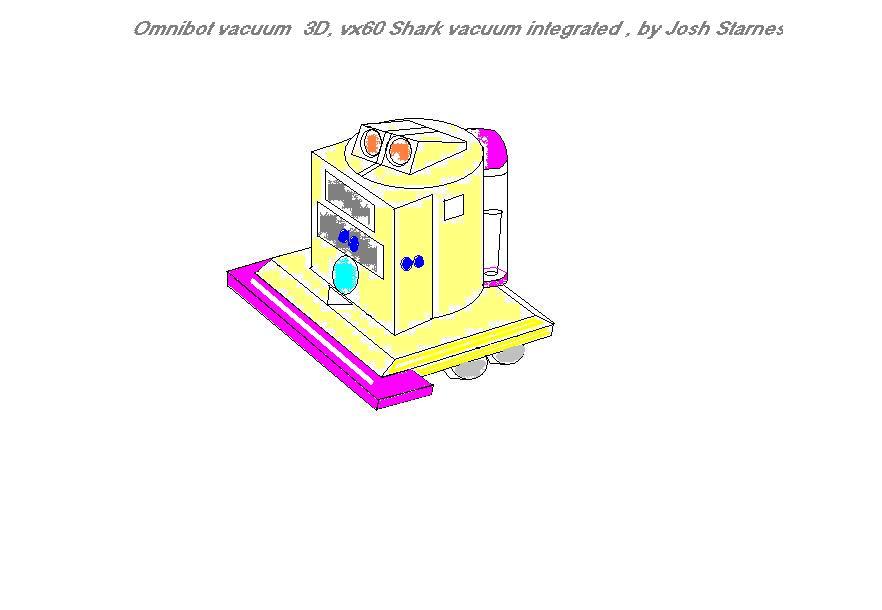
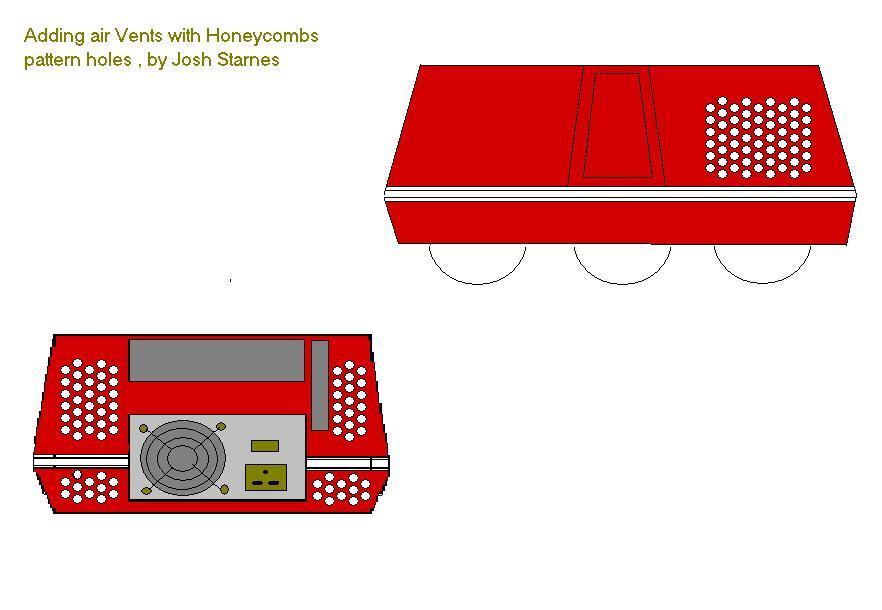
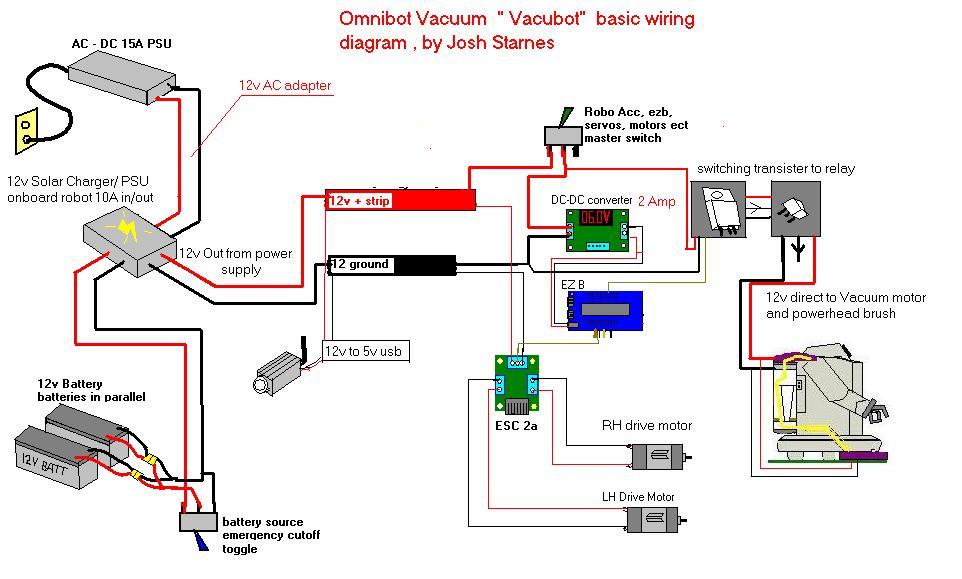
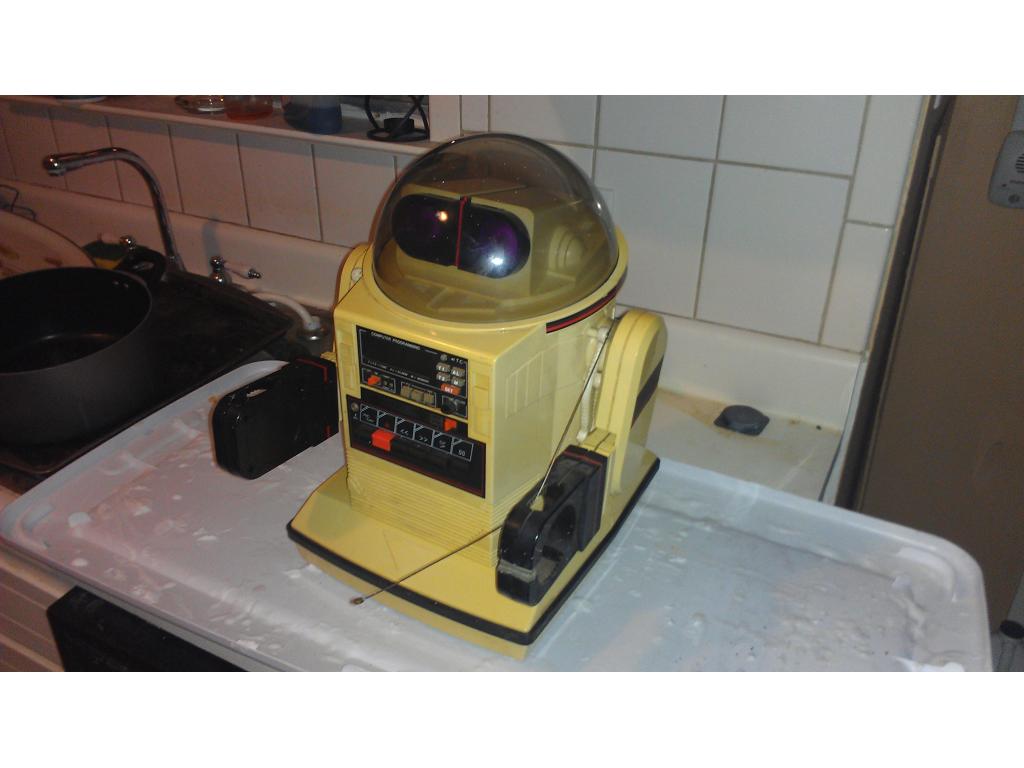
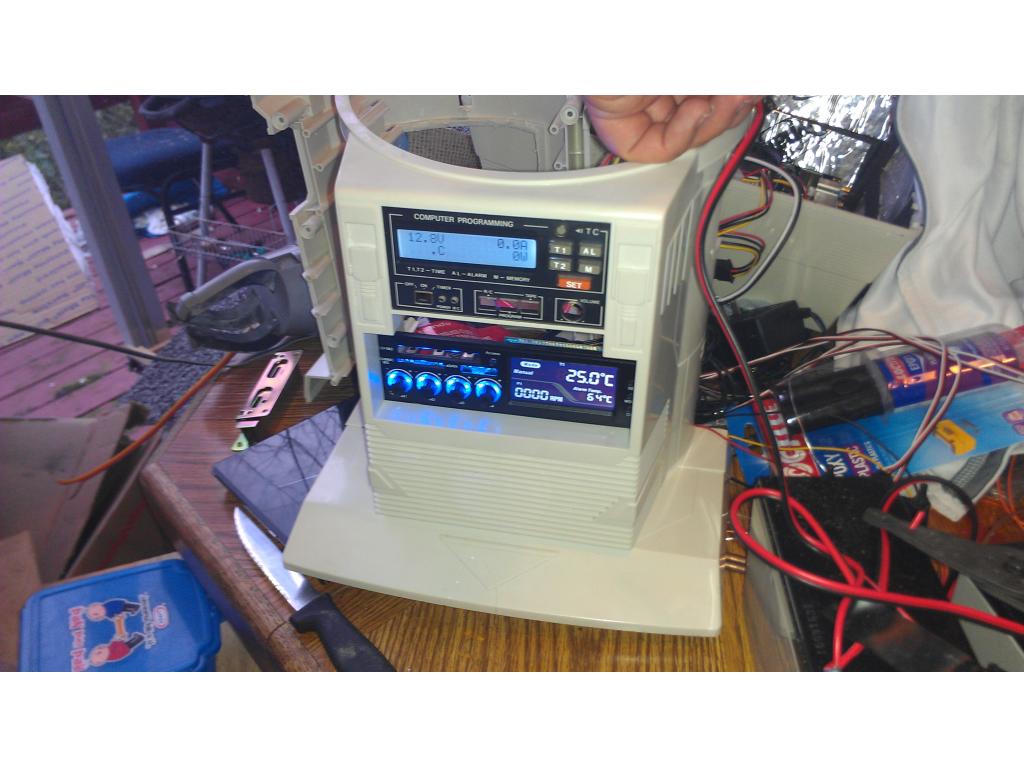
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.

By jstarne1
— Last update

Discover more robots
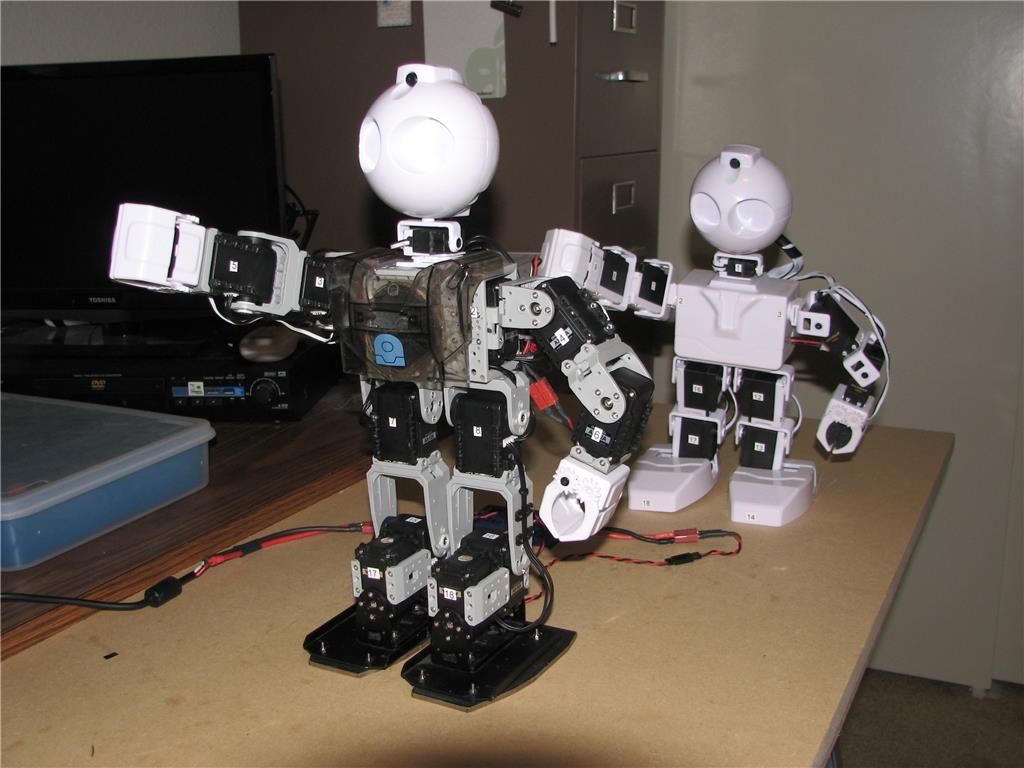
Oldbotbuilder's Baxter With Ax-12 And Iotiny
Baxter JD clone using EZ-B4/ioTiny and AX-12 servos - performs JD actions; includes power, servo mapping, USB2DYNAMIXEL...
Ezang's My New Metal Robot With Voice Commands 10/25/2019
Metal robot with voice commands and automatic positioning for easy viewing and interactive demonstration
Ezang's My New Intro To My Metal Robot With The Arduino
Metal robot with Arduino: an introduction to the project and an invitation for feedback

Truckee is near lake Tahoe. More of a ski town.
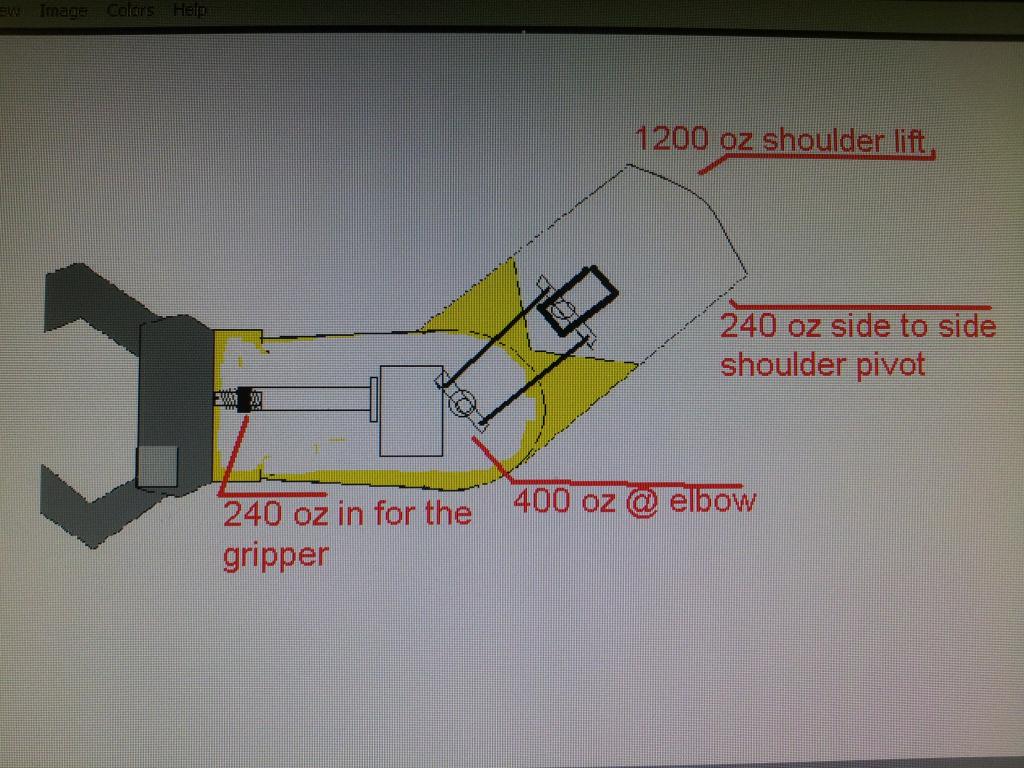
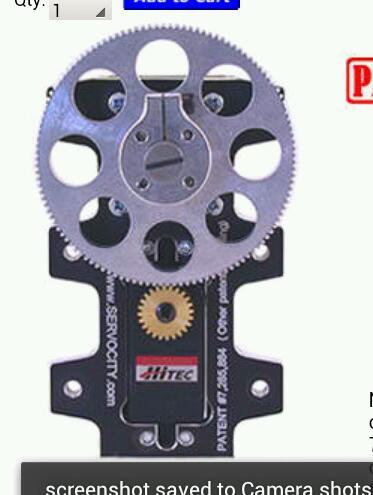
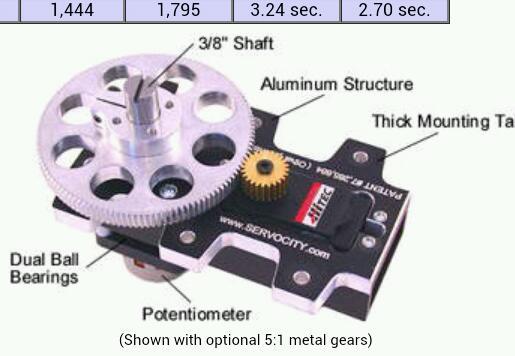
Ok update on Jarvis , plan for gripper , strong , quick and most importantly accurate.
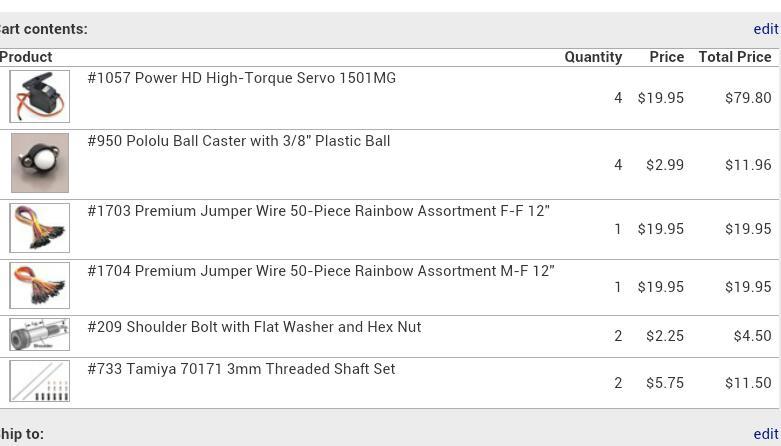
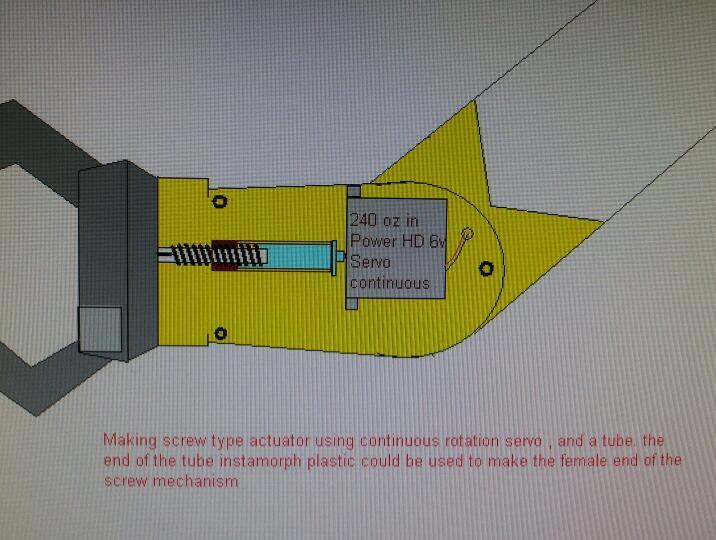
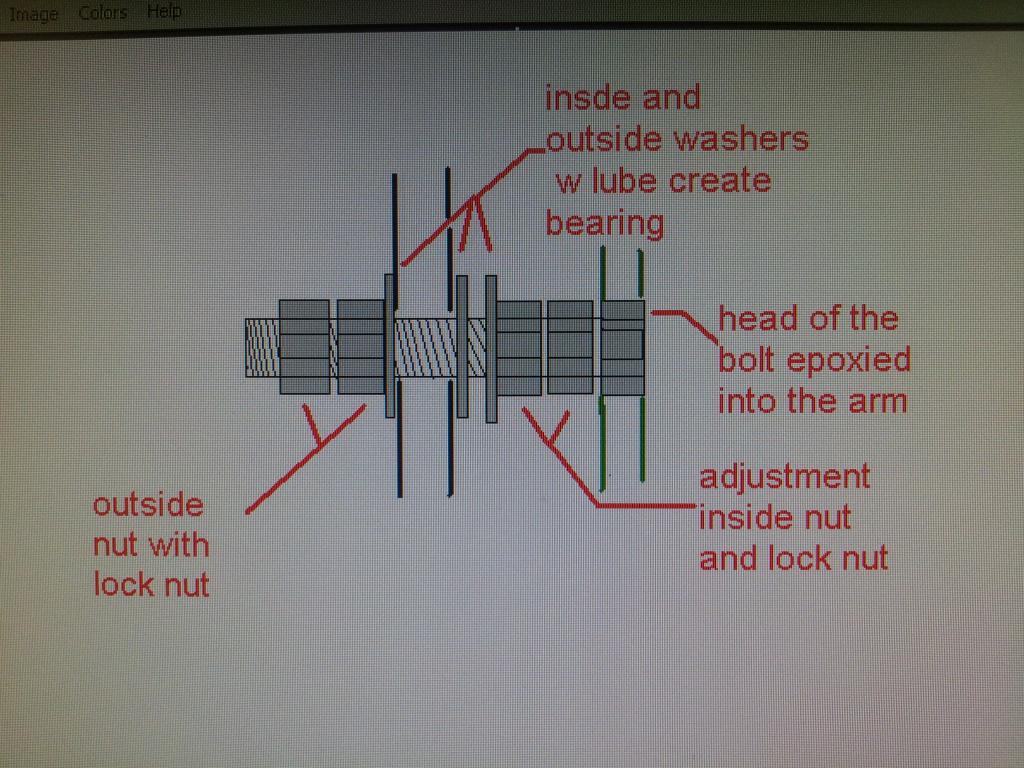
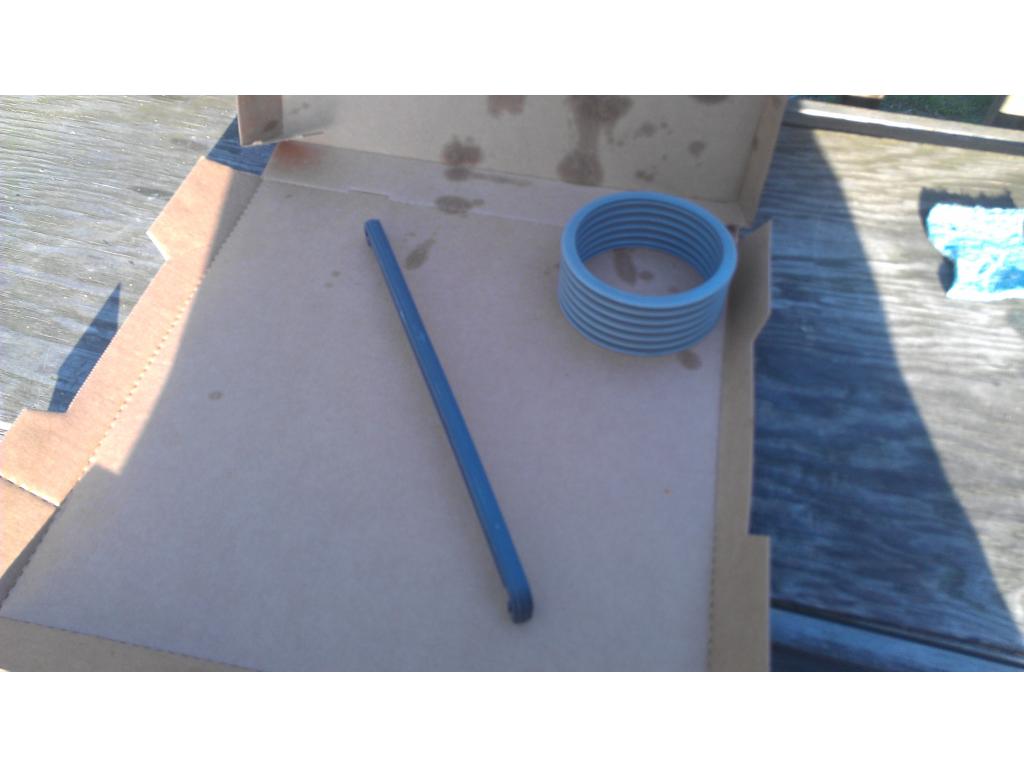
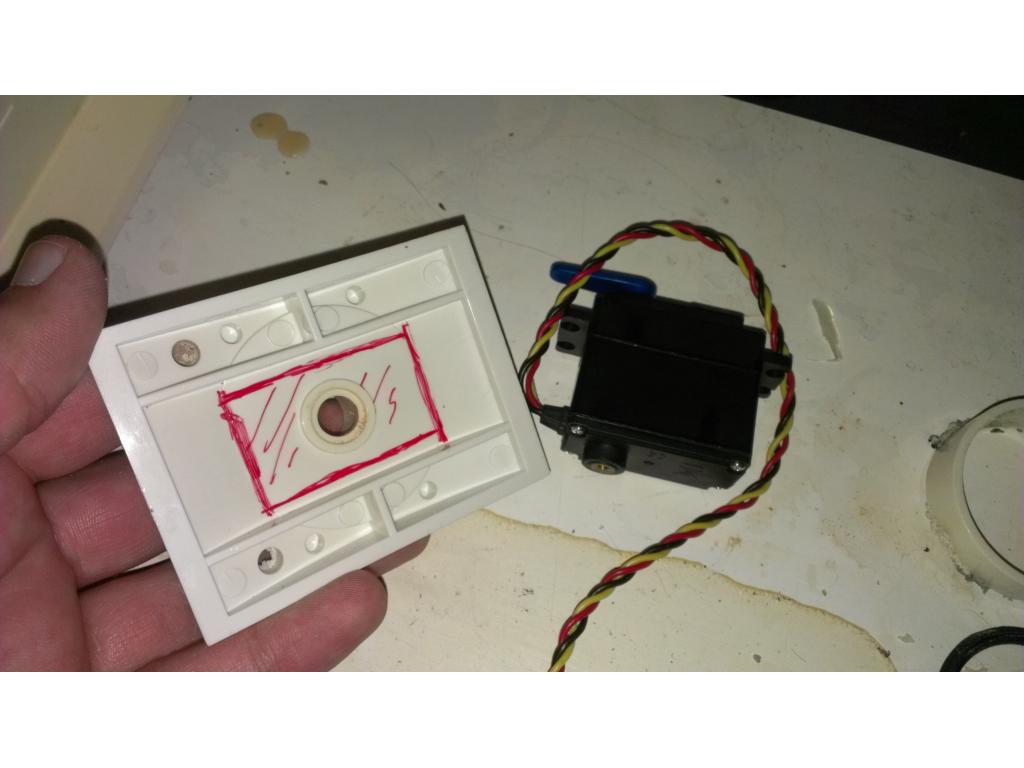
This is a linear actuator made from a tube epoxy glued to a servo horn , the other end has the screw on it. The servo used must be modified for continuous rotation.
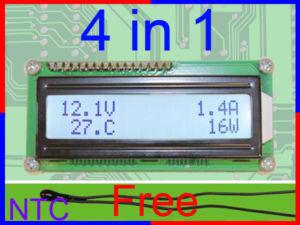
Josh how are you monitoring power levels?
This thread is so huge it's hard to find info...
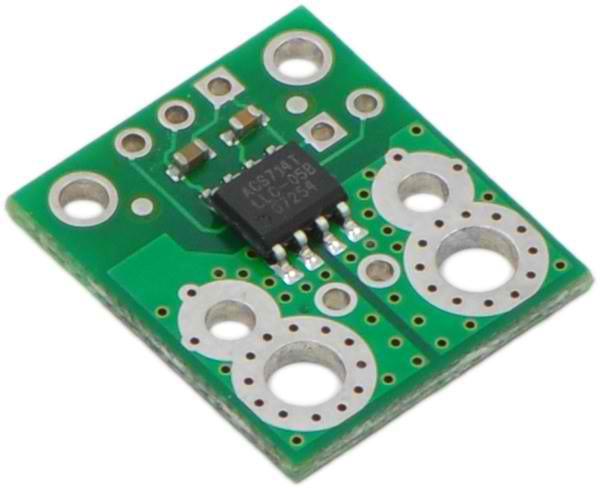
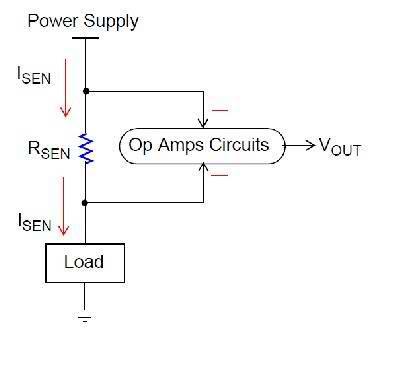
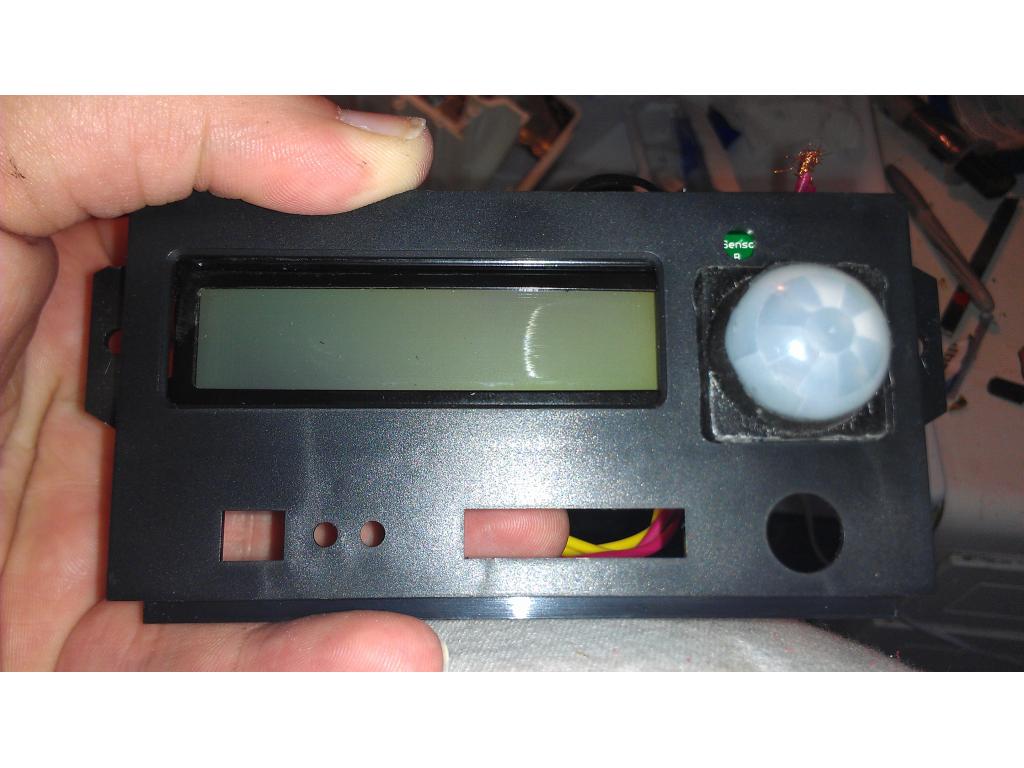
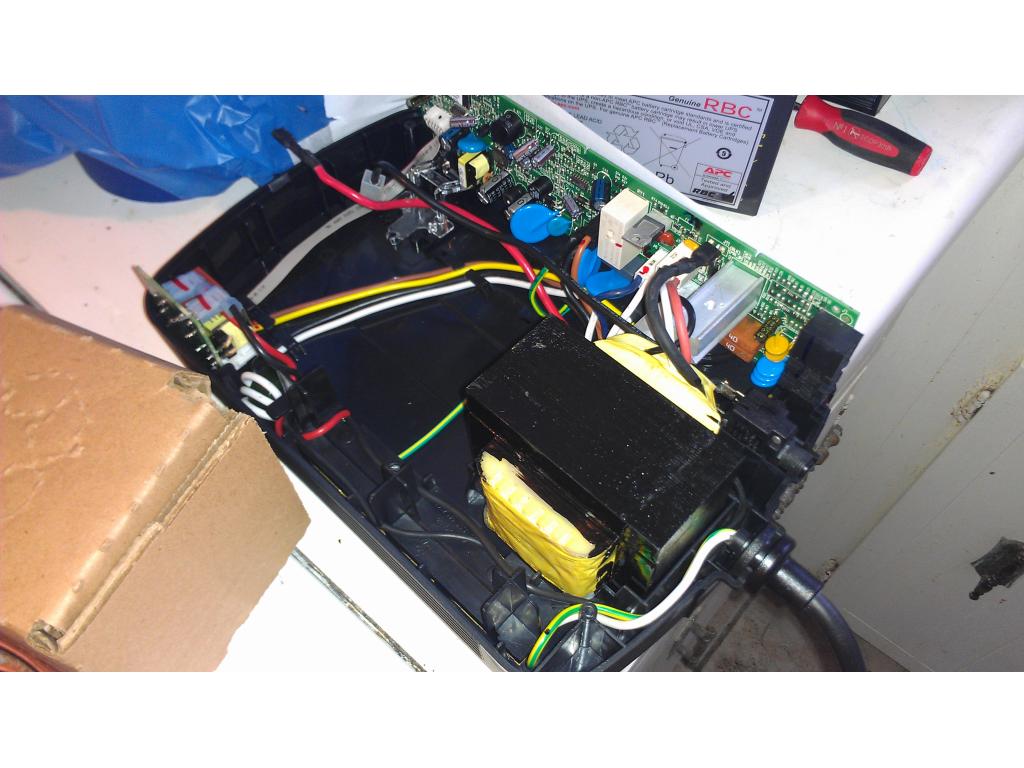
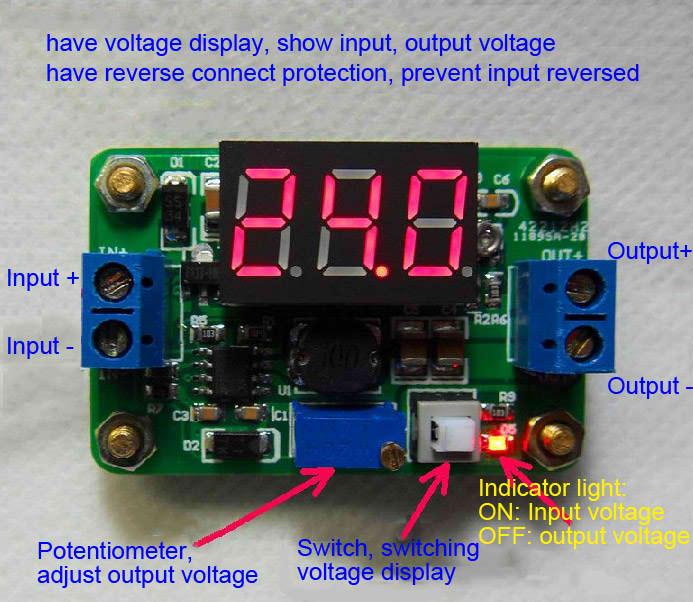
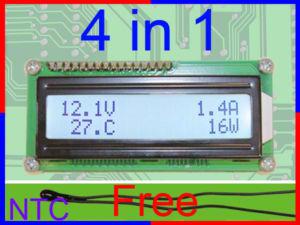
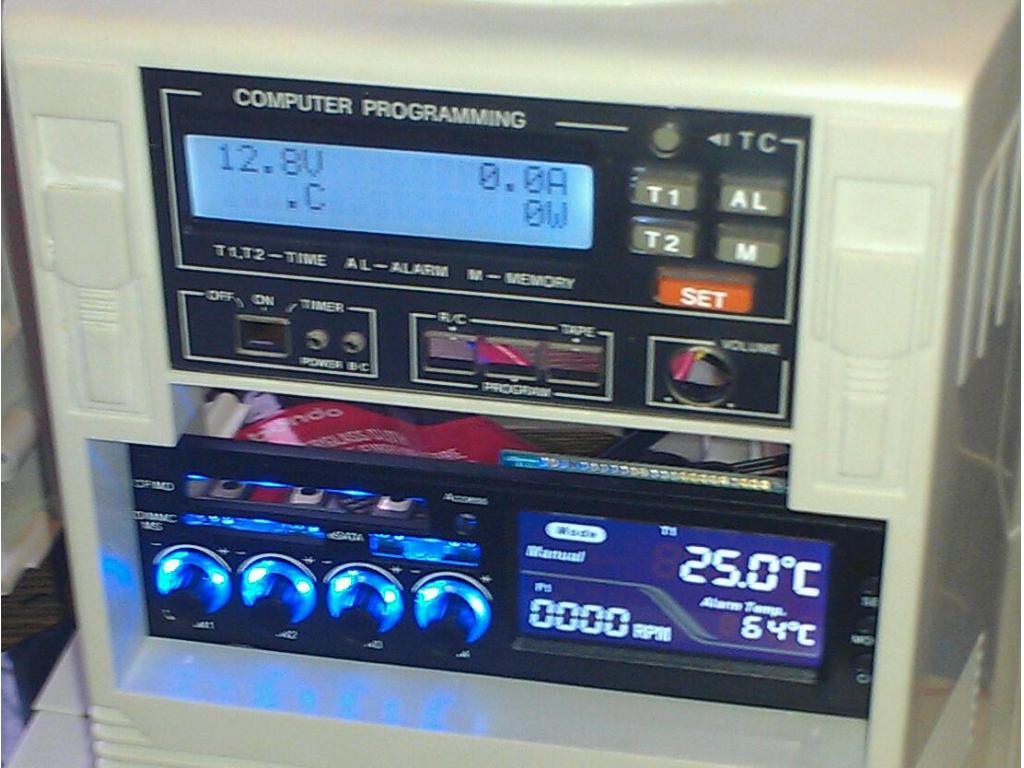
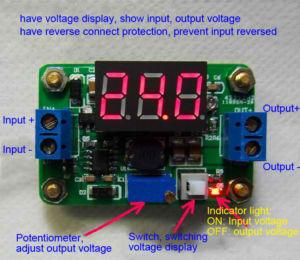
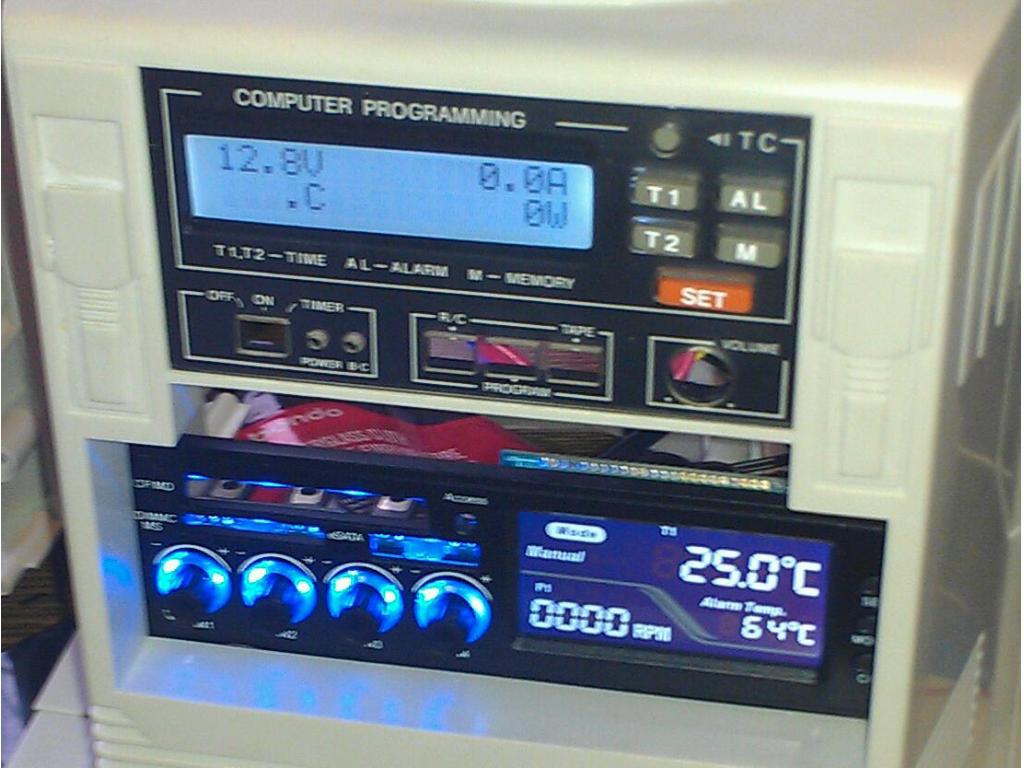
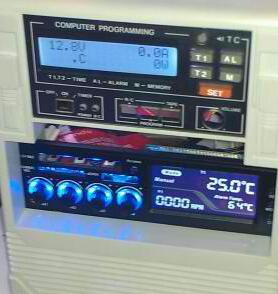
Jarvis has a visual LCD showing volts , Watts consumed and amps. The power supply I have has a USB interface showing battery levels too which is super cool. I used the control board from a apc battery backup 400 watt version.
SFOY sking is much much fun,mosty rent mine at the resorts i stay at,and water sking i do ,i think i like it more
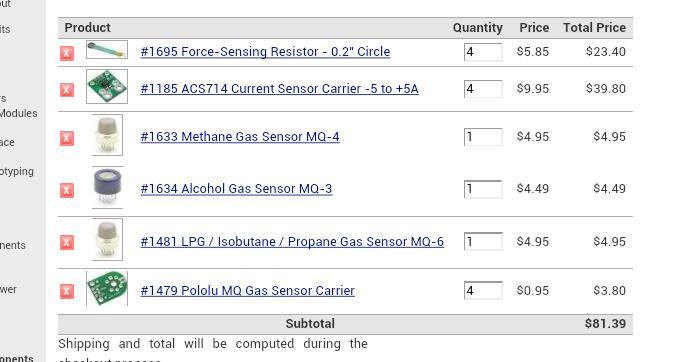
JOSH the idea you have there looks ok,and should work ok,only problem it takes up much room,i am looking at other ideas ,just as strong and accuracy is still great i am also adding force sensors on the tips and flex bend sensors on the arm and elbow
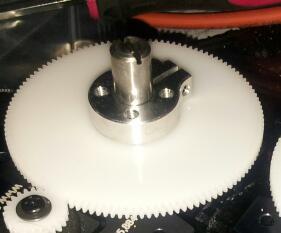
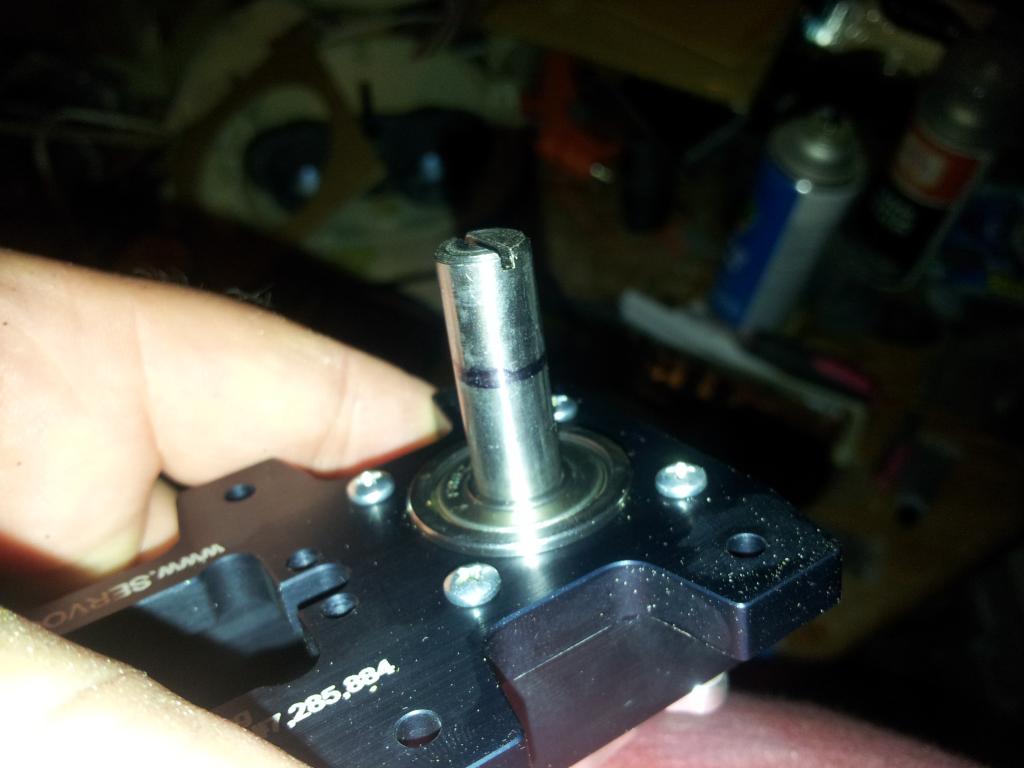
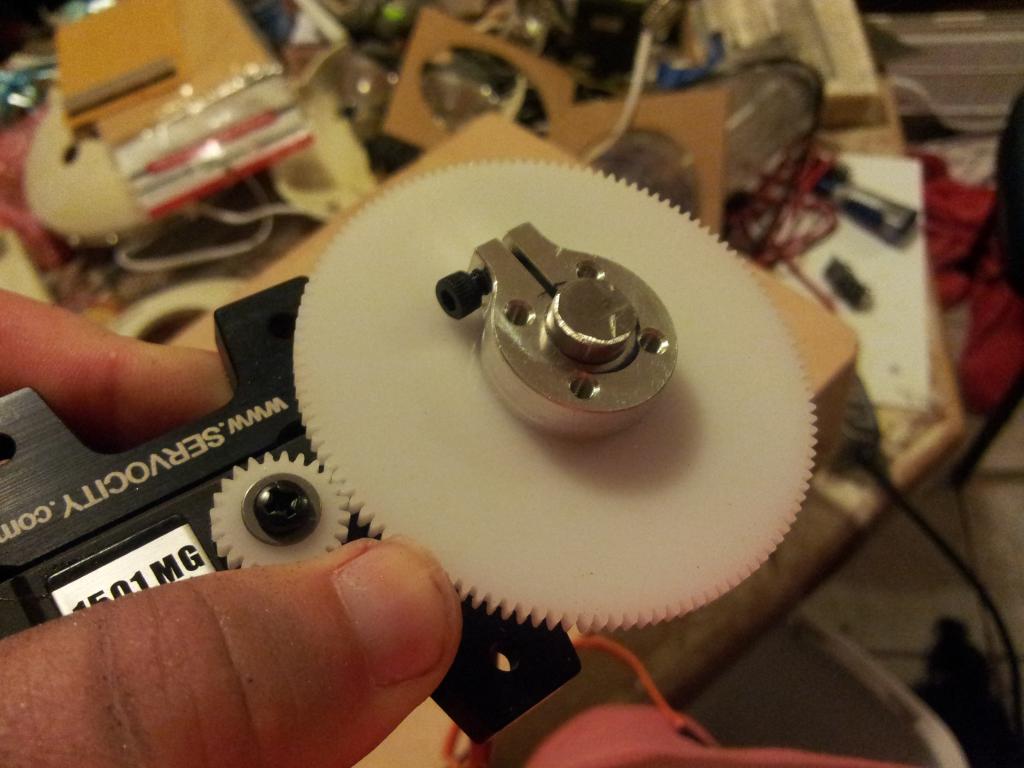
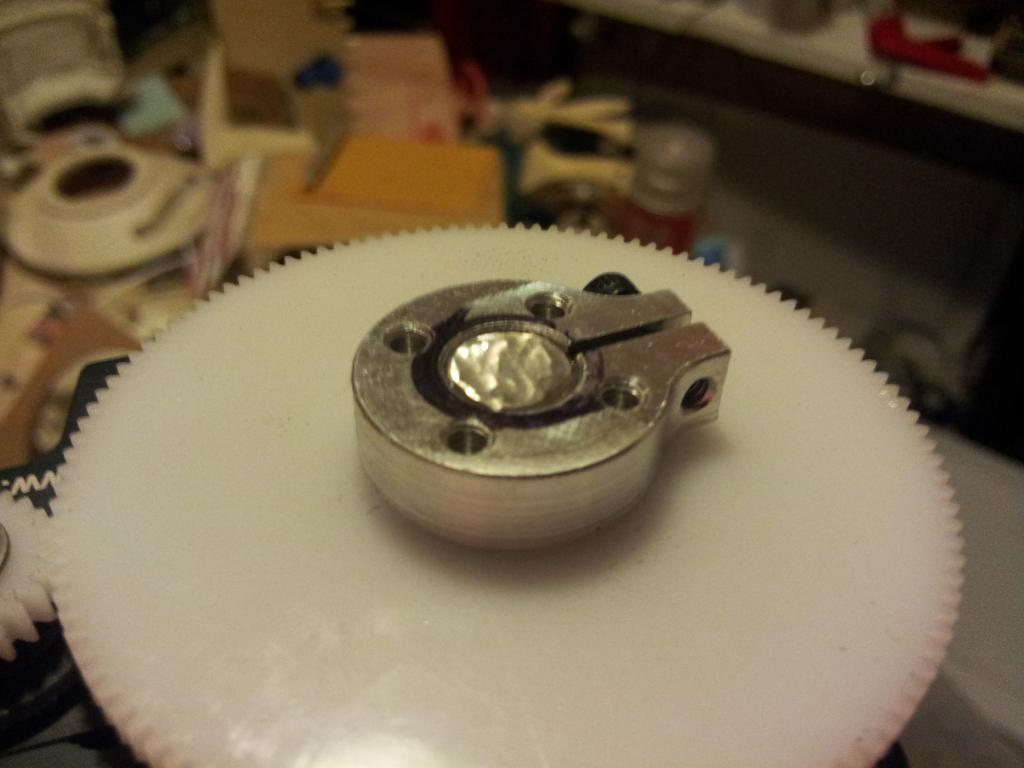
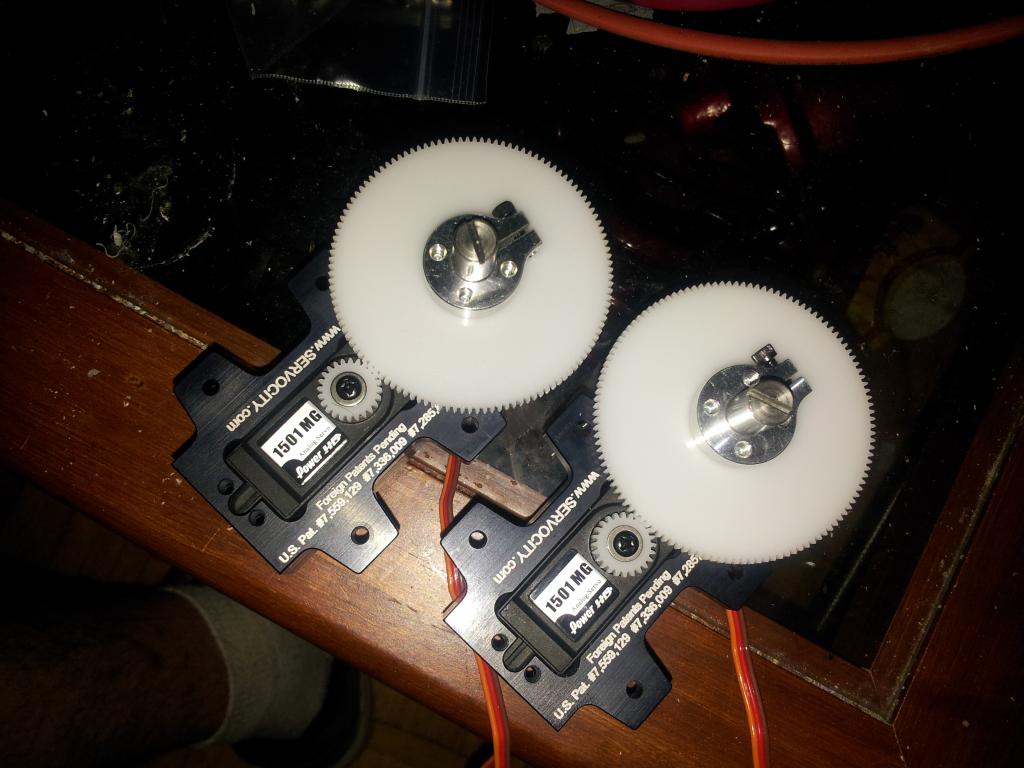
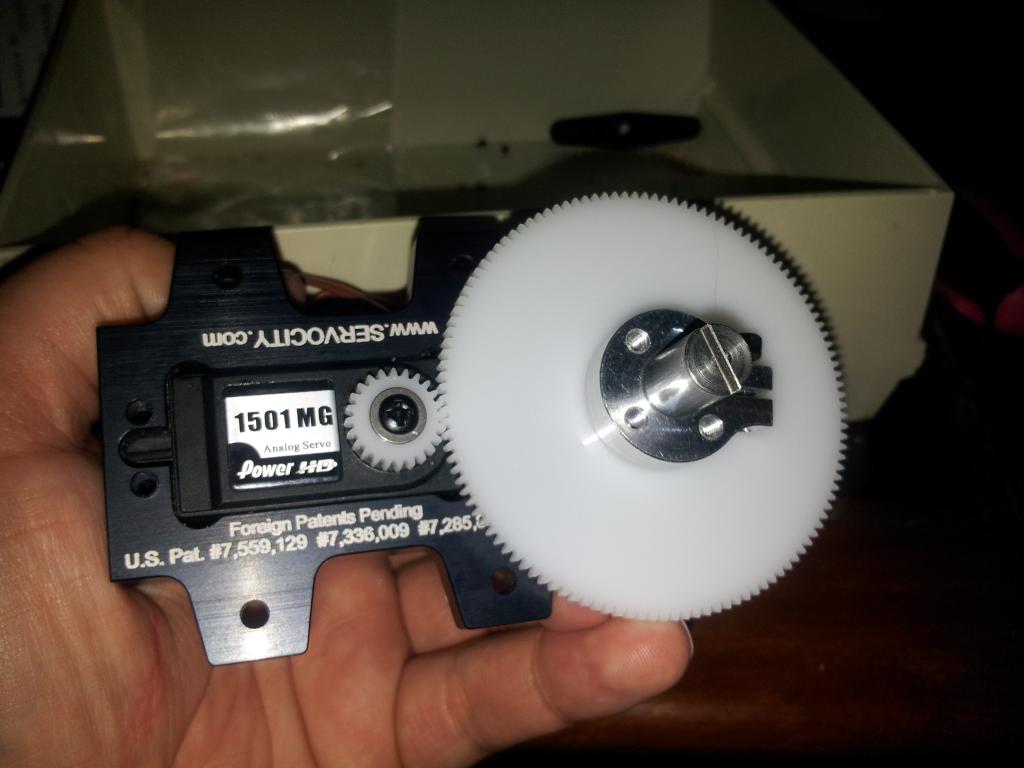
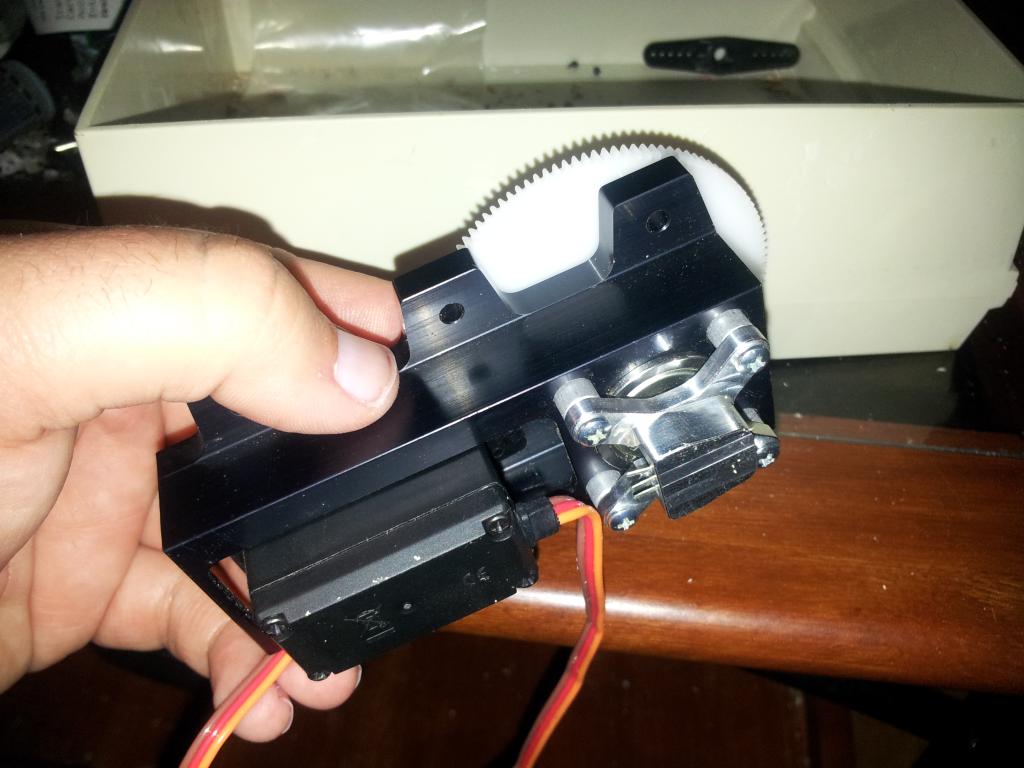
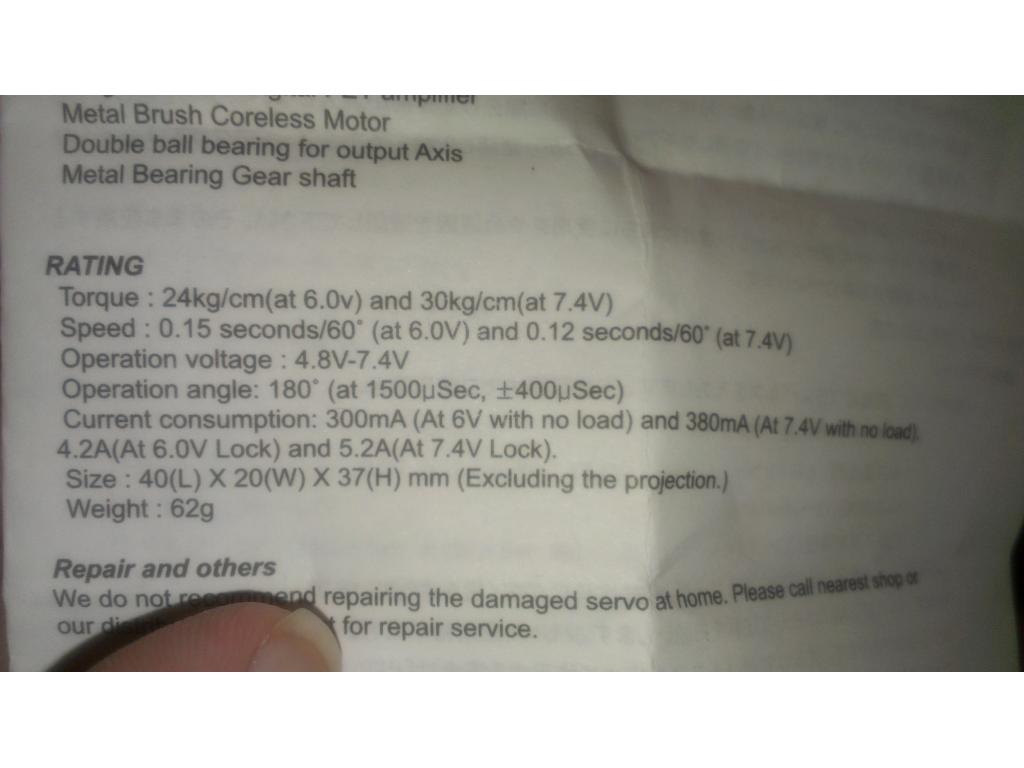
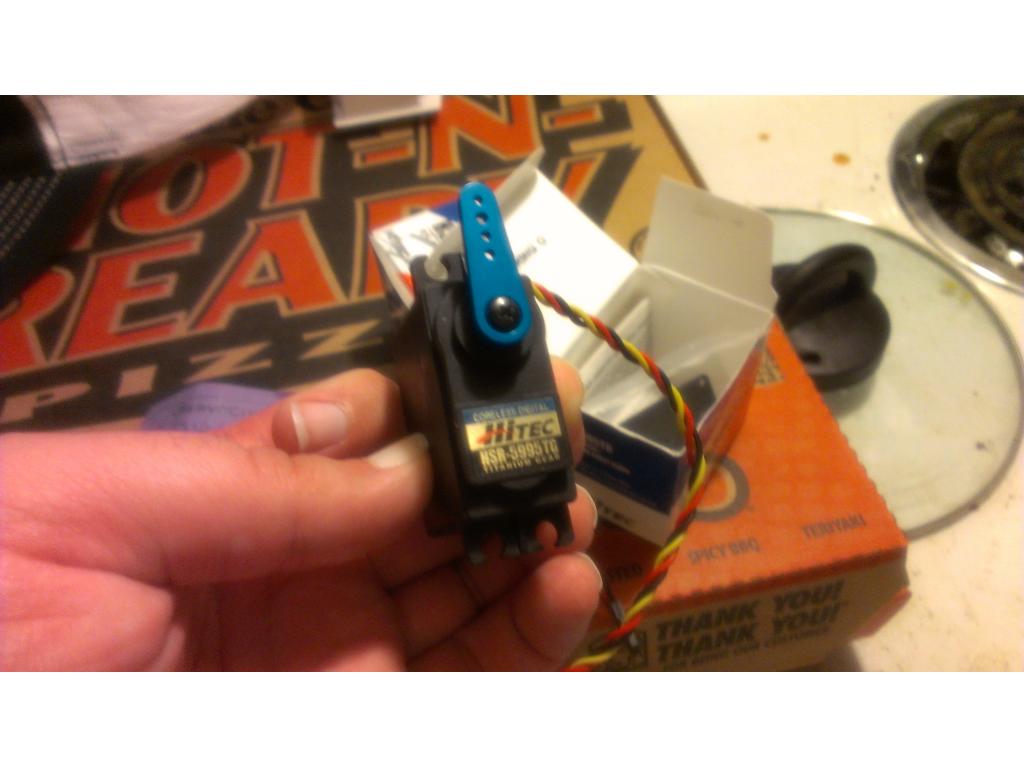
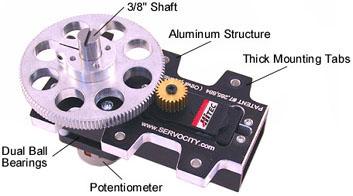
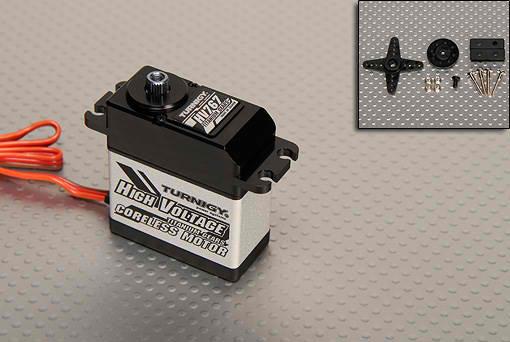
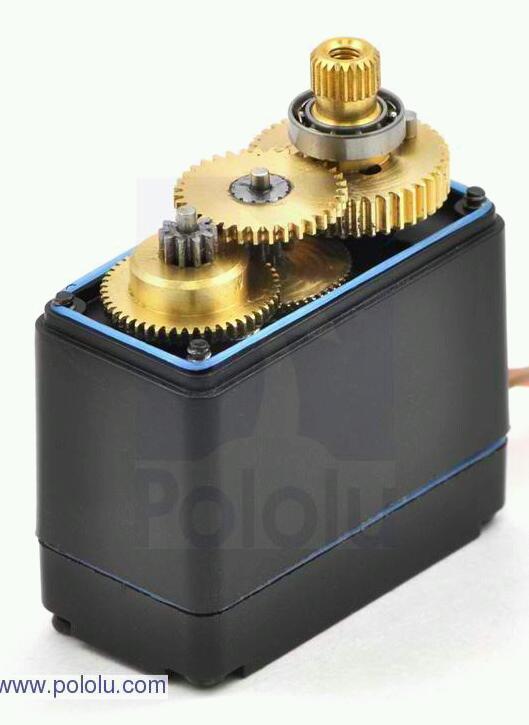
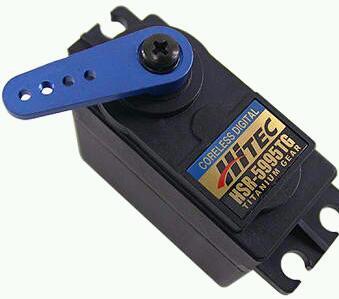
Well there is enough room , I could have used smaller components but I wanted it to be strong enough. Anyways I decided to use the 5995tg servo for either the elbow or side to side shoulder movement. Now I just need a way to hook up a 6 turn pot on that shaft.
on 240 oz and since not using a arm you should get close to 15 lb holding power,but at only a few seconds,since thats stall torque,and you go use much less like 10 to 12 lb holding torgue,so be very carefull you dont go near the 15 lb holding grip or servo will burn up
Do you think that's good for holding power? Considering he needs to grab beer bottles and wine bottle? One benefit we realized is with a screw type once the bottle is gripped the servo could release and it would not drop the cup / bottle.