


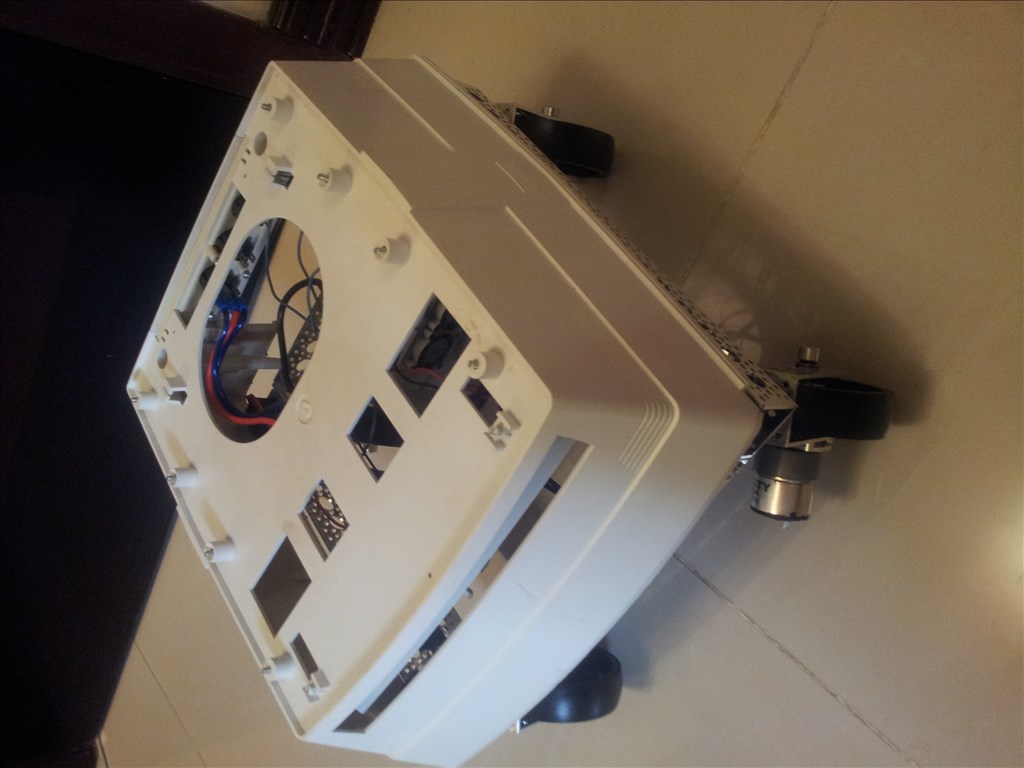
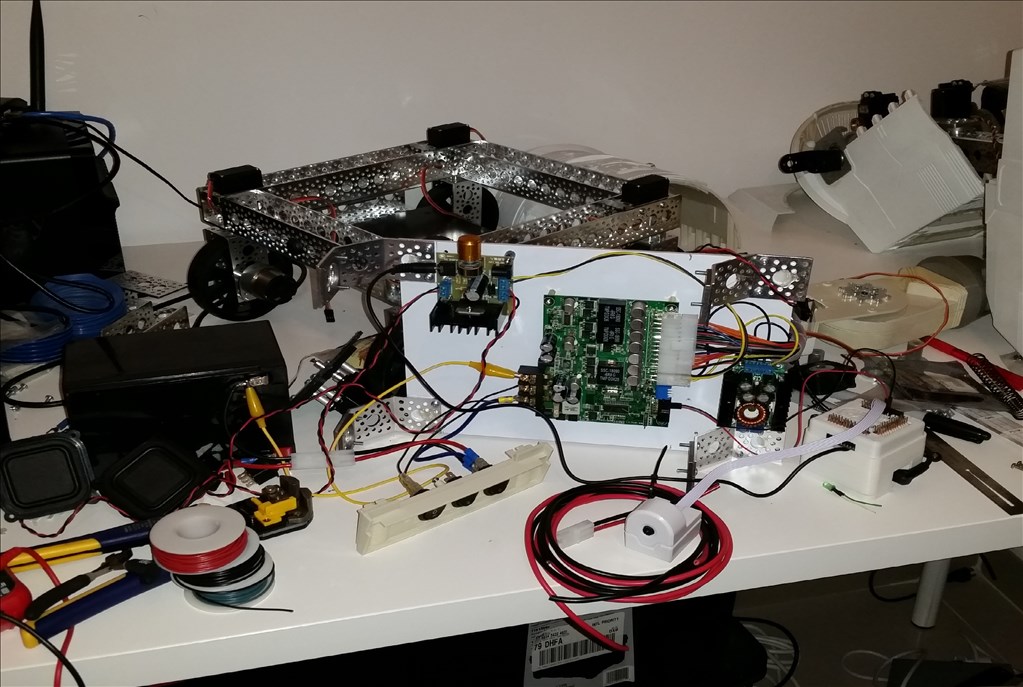
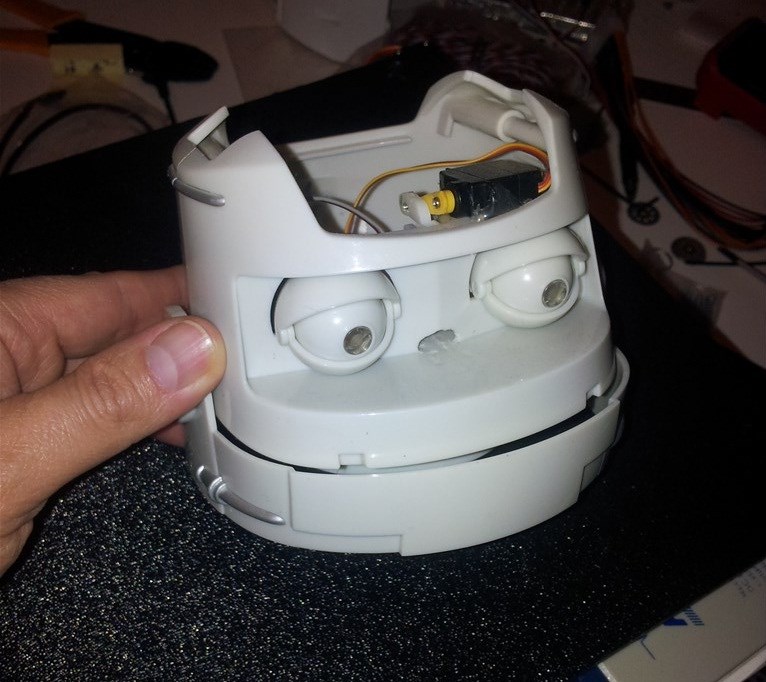
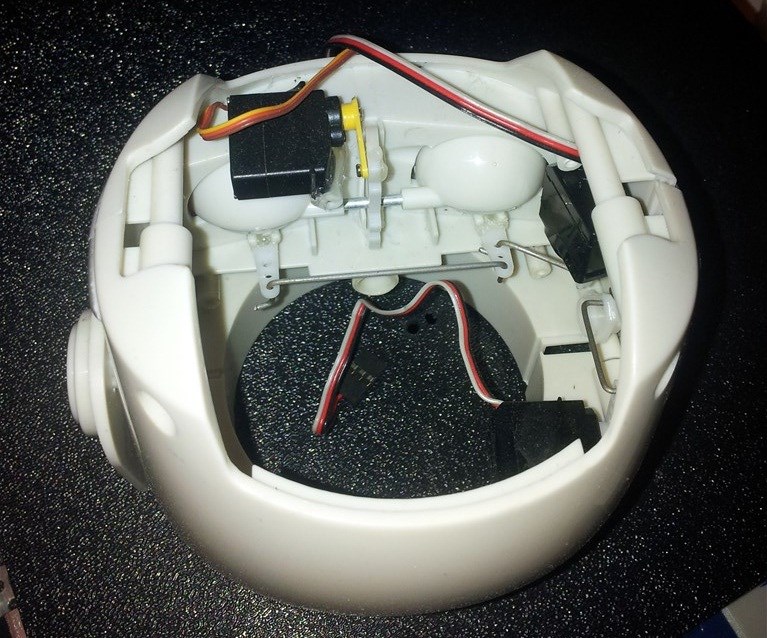
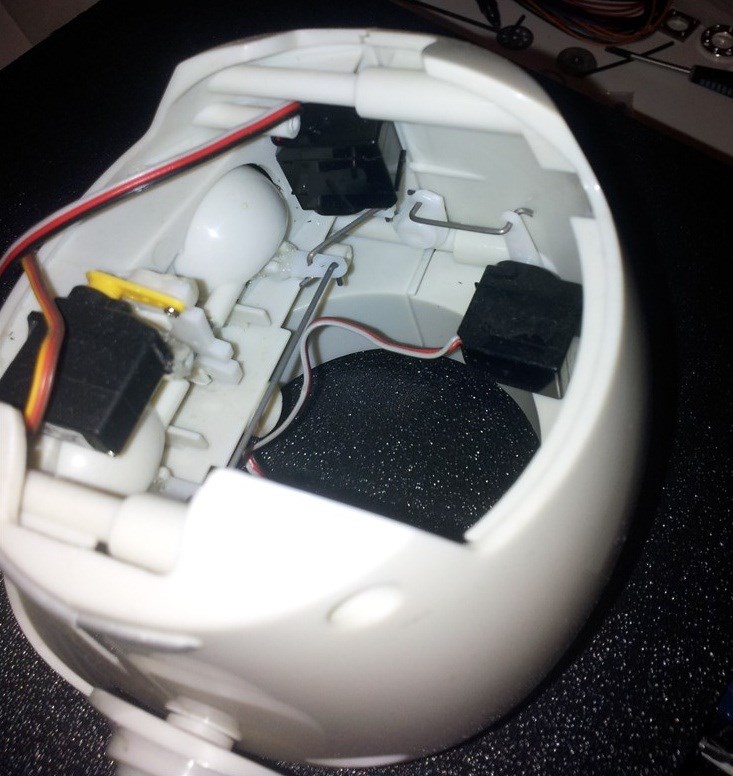
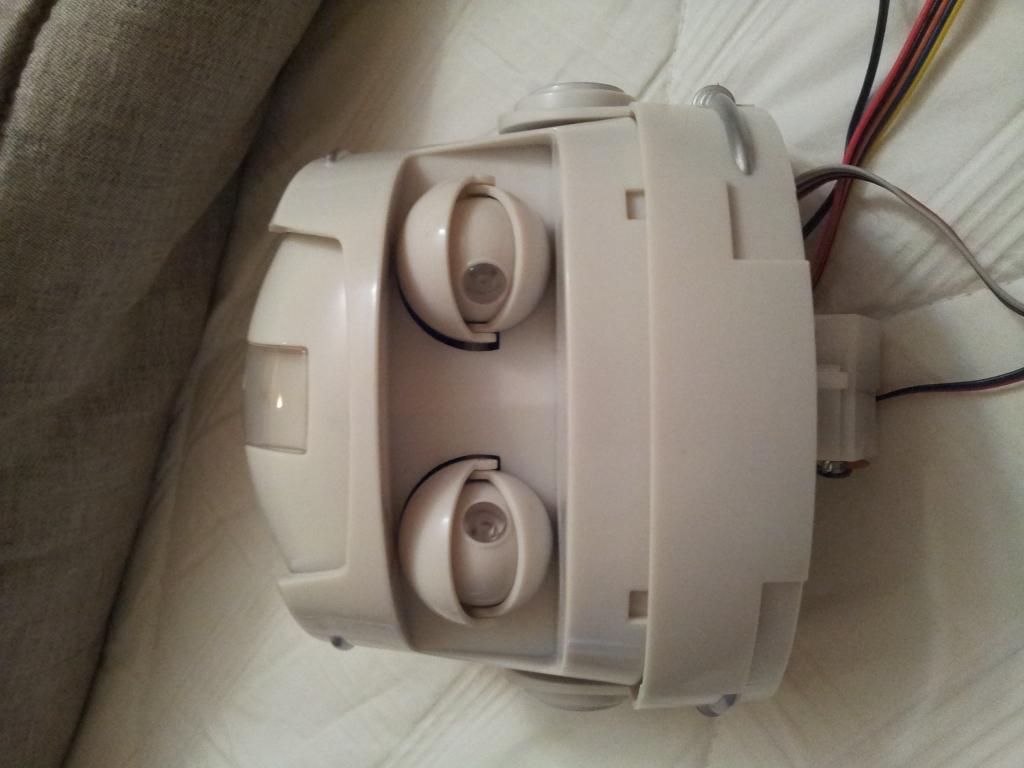
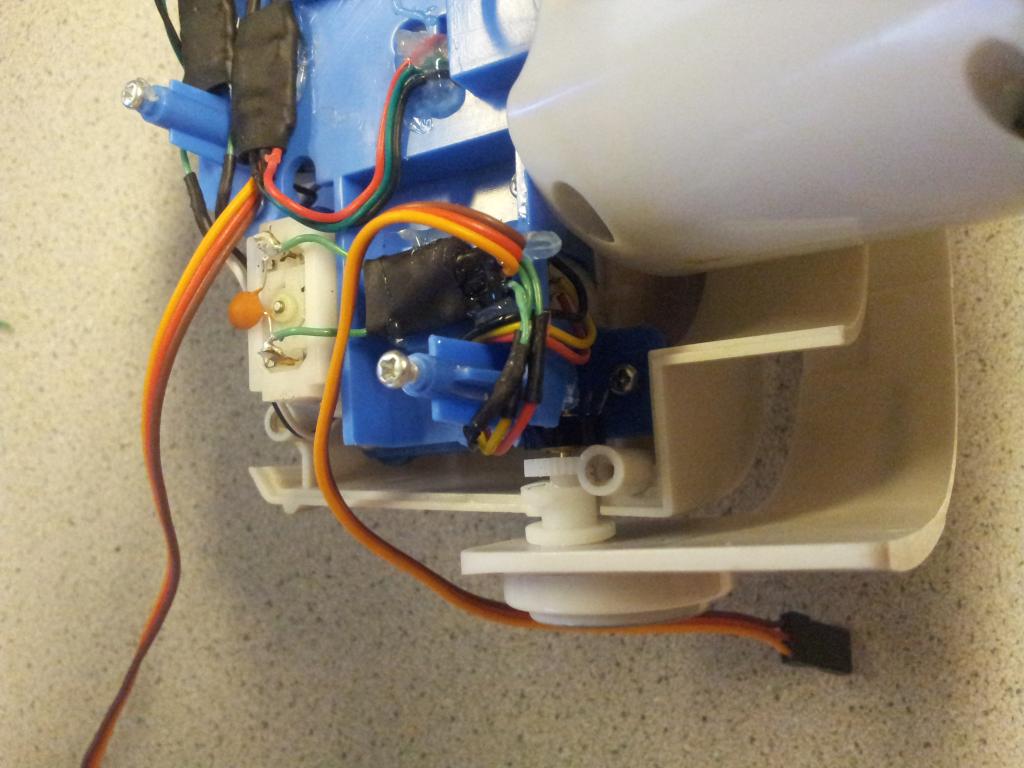
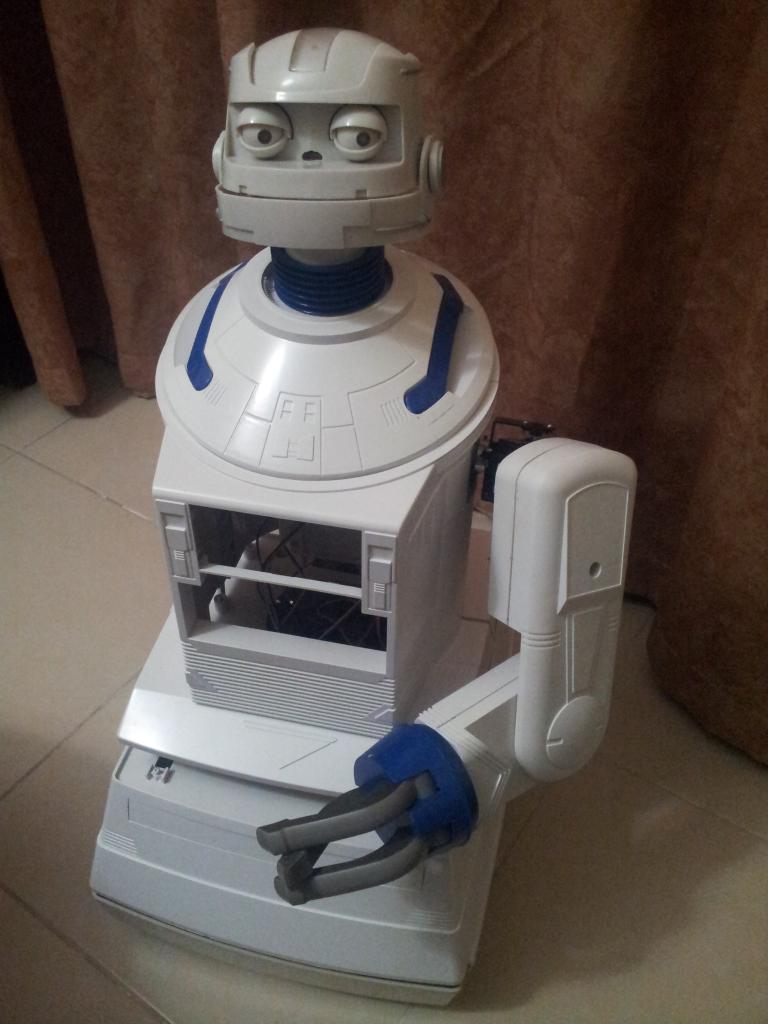
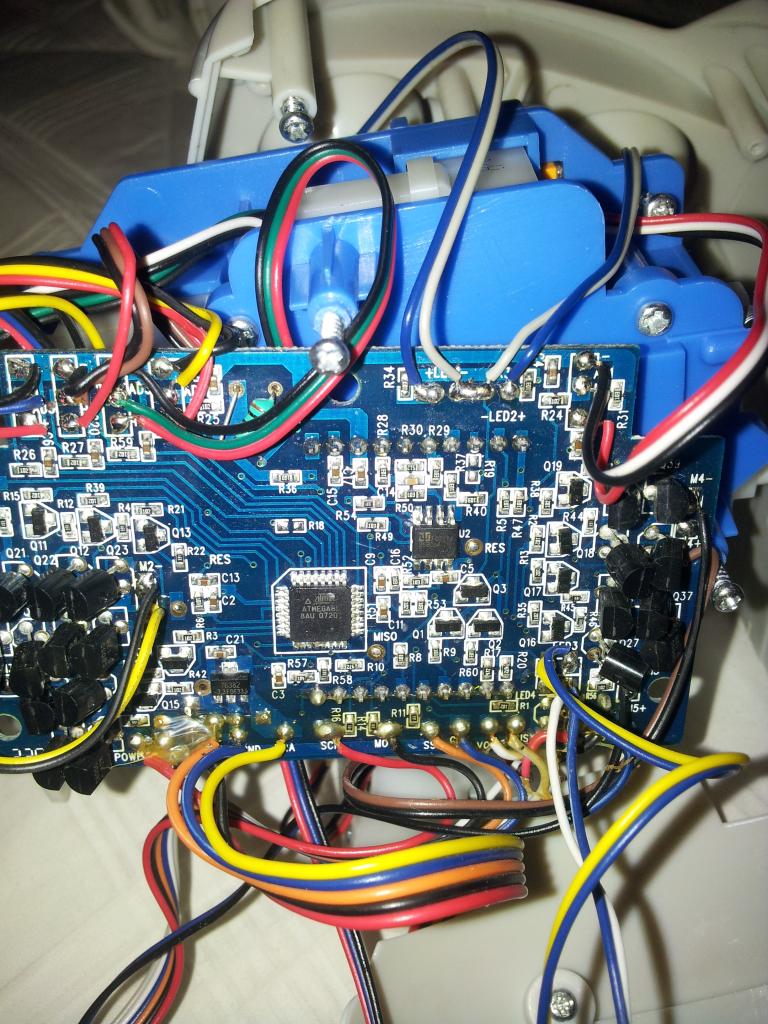
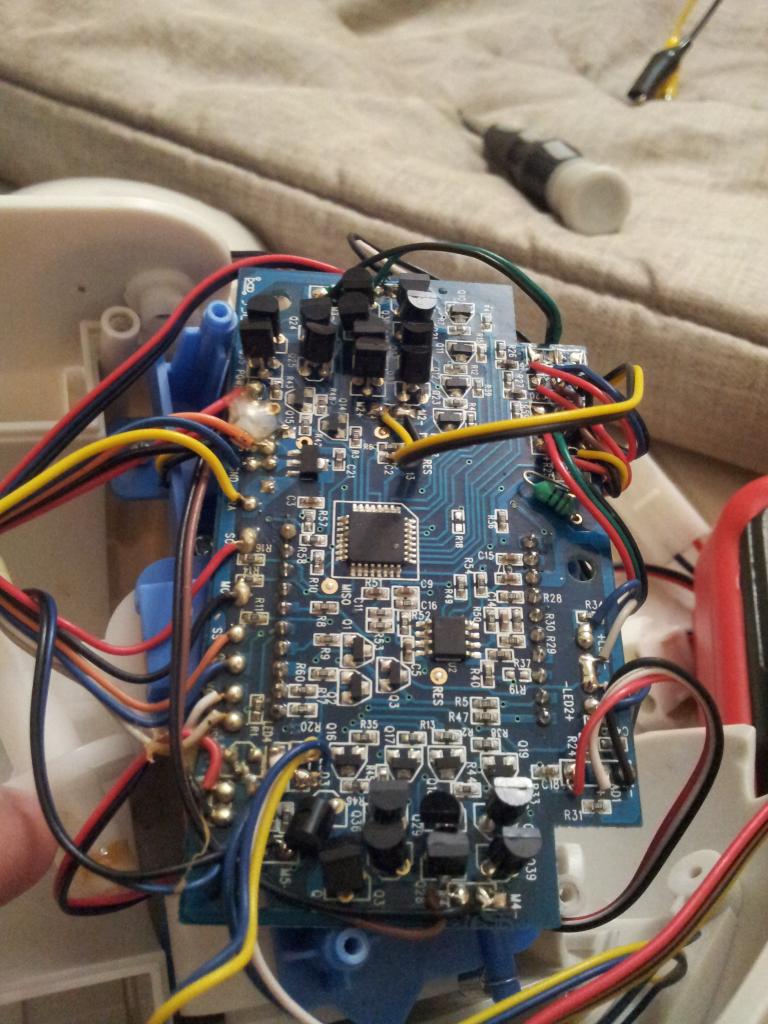
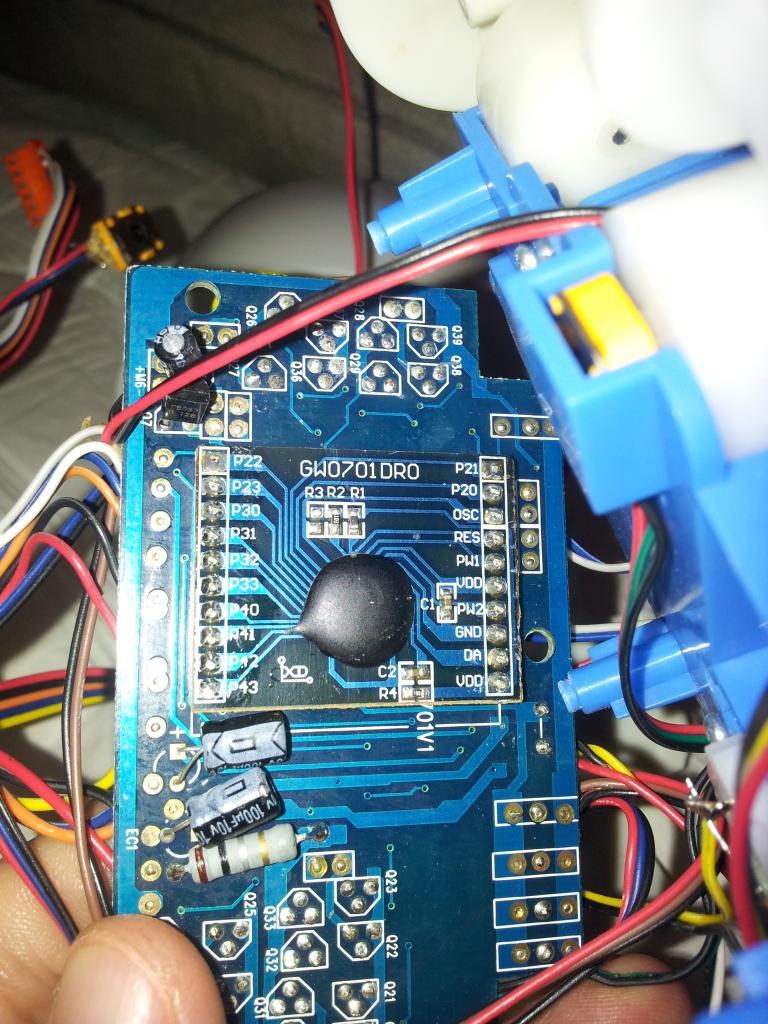
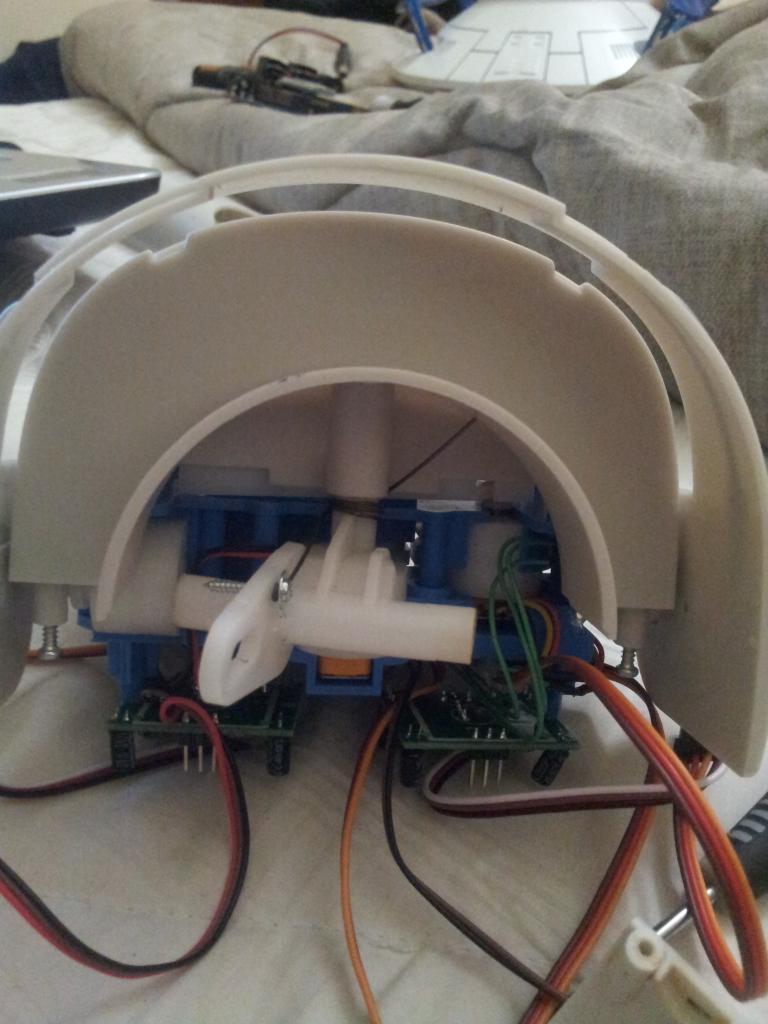
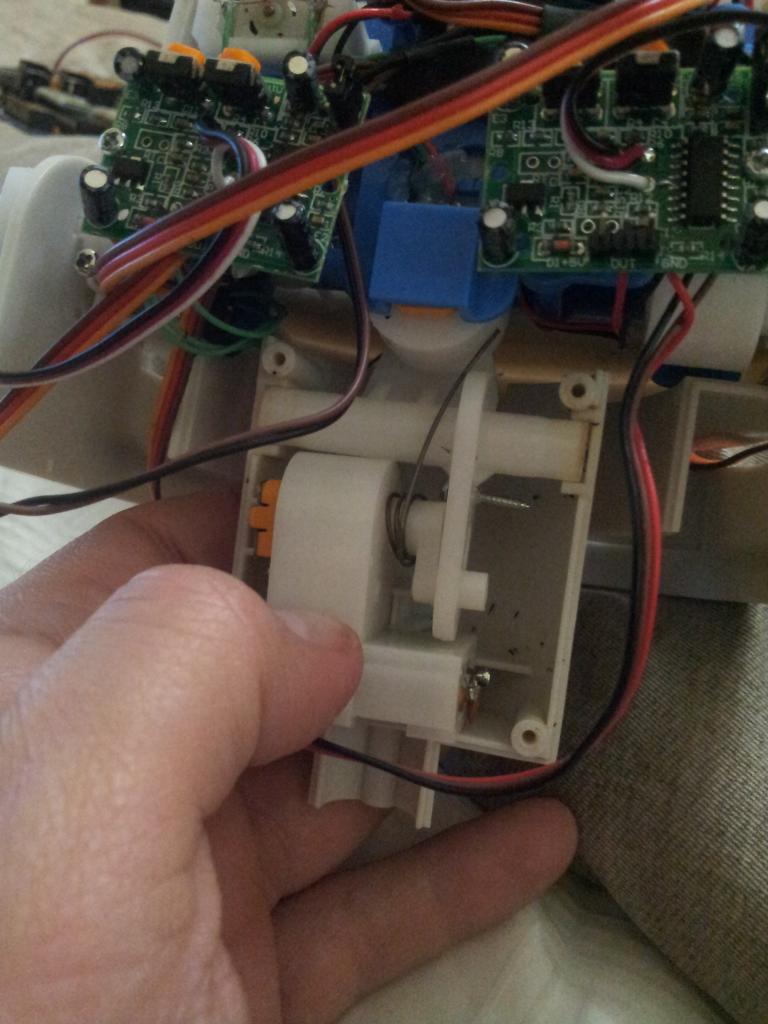
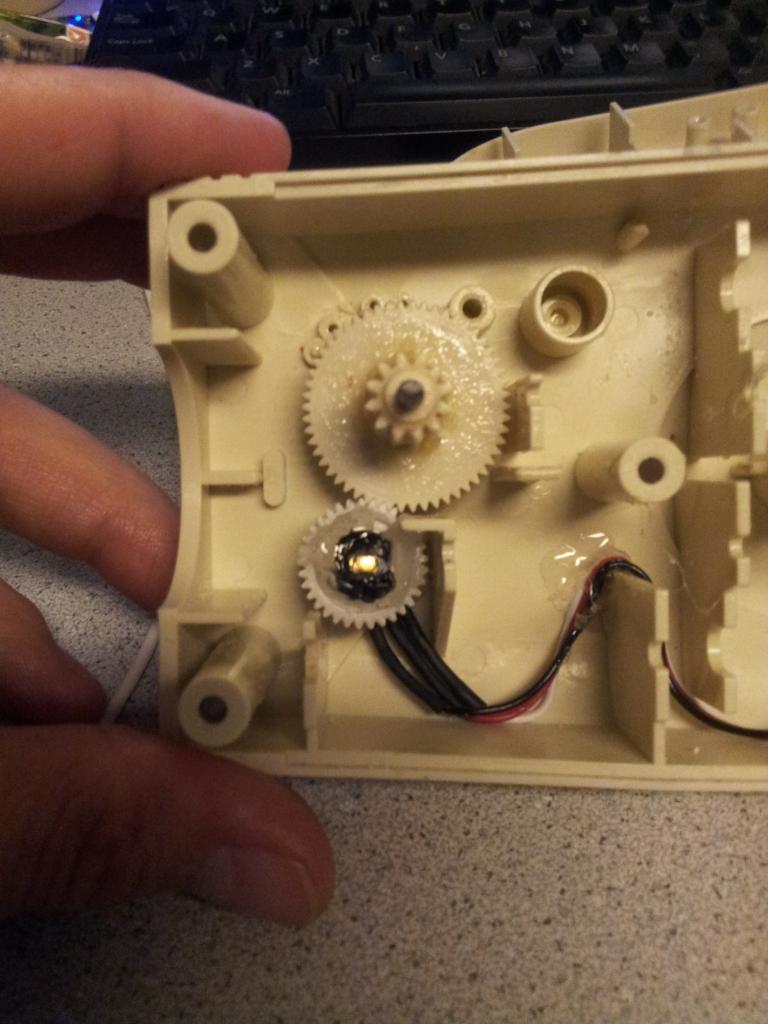
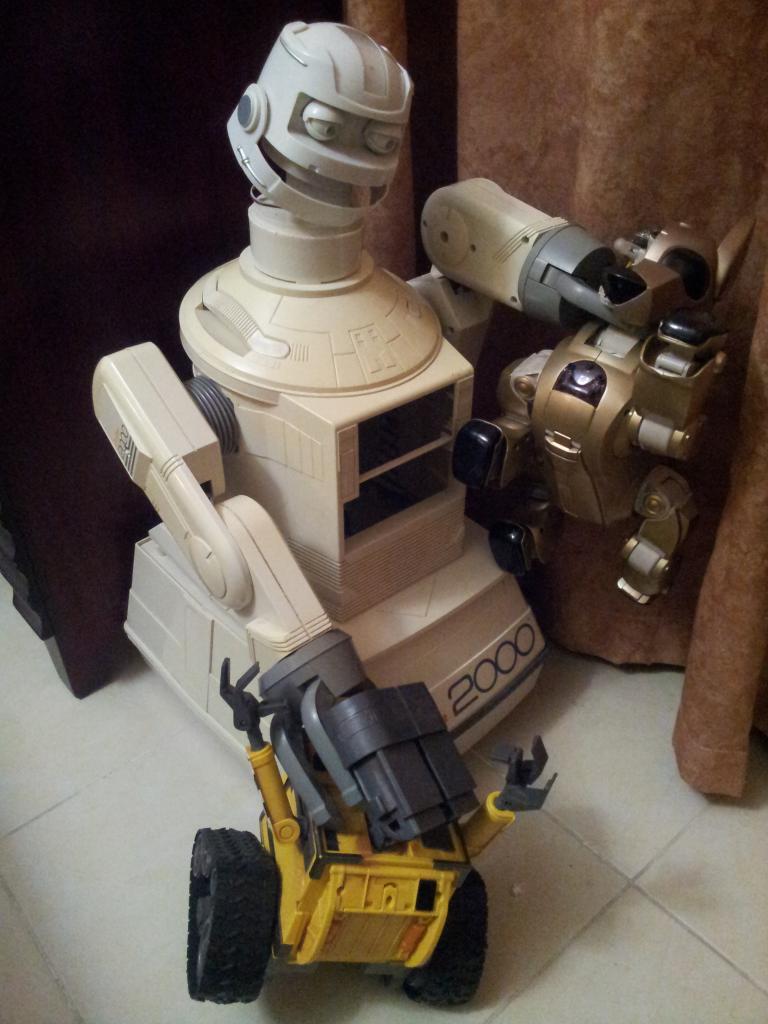
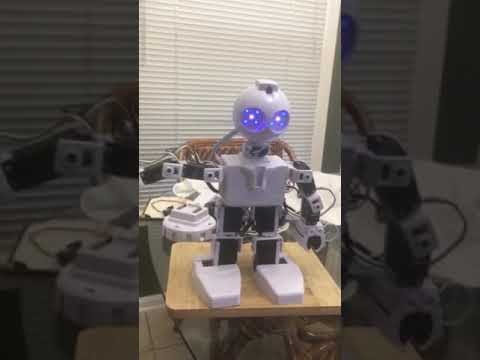
It's just a concept right now but I wanted others to see that the scale doesnt quite match. Right now its just stacked on there and neck is a little too long.
By Troy
— Last update
Discover more robots
Jstarne1's Calling All 3D Printers! Get The Stls While They...
LEVi Rover 3D files assembled and ready to print, with model cuts for smaller beds and community tips for printing and...
Ezang's Let's Have Some JD Robot With Voice Commands
JD robot voice control with left-right head movement for natural, responsive interactions
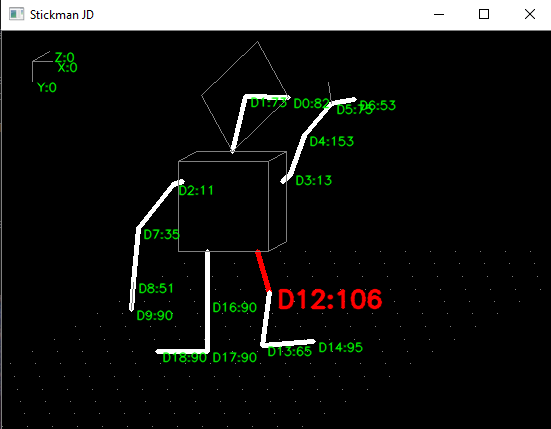
Goldenbot's Stickman JD Robot V1.1
Control JD Humanoid in Synthiam ARC with Stickman JD: 3D joint dragging, rotate view & floor grid, works with EZ-B...

Wow! That is a cool looking robot!
Thanks but it won't be as good as others projects here.
Project robots are always in evolution Troy I really like the head look as well, very creative....
"but it won't be as good as others projects here" there are no competitions here! ...though there may be "bot envy"
 Looking forward to the "reboot" rebot?

hehe Yes I agree there are no competitions but I meant that I envy what others have created.
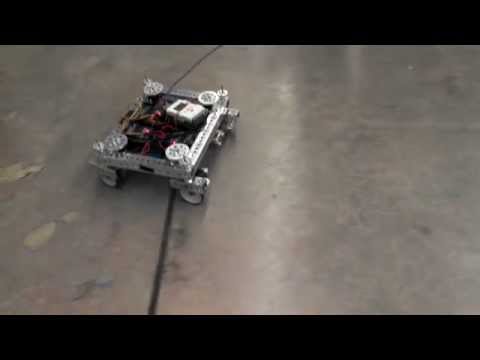
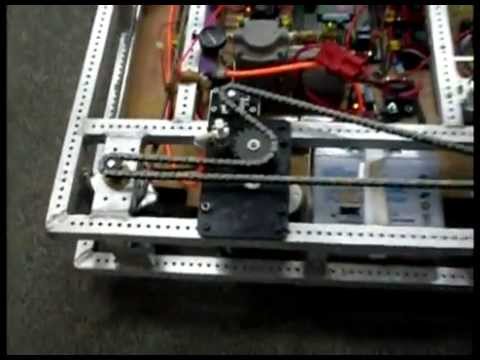
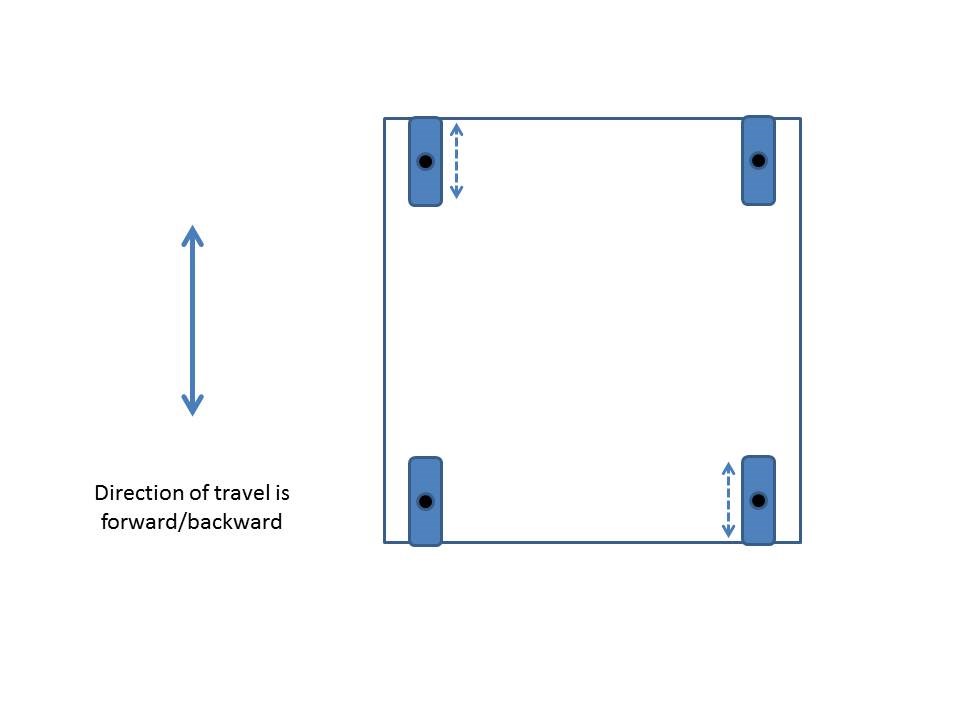
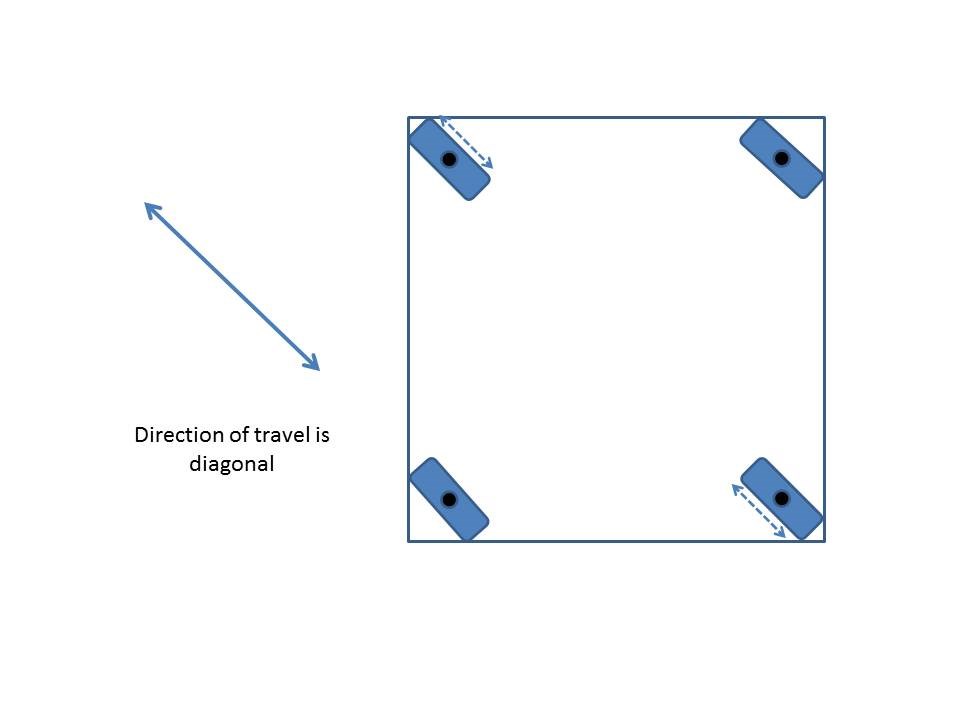
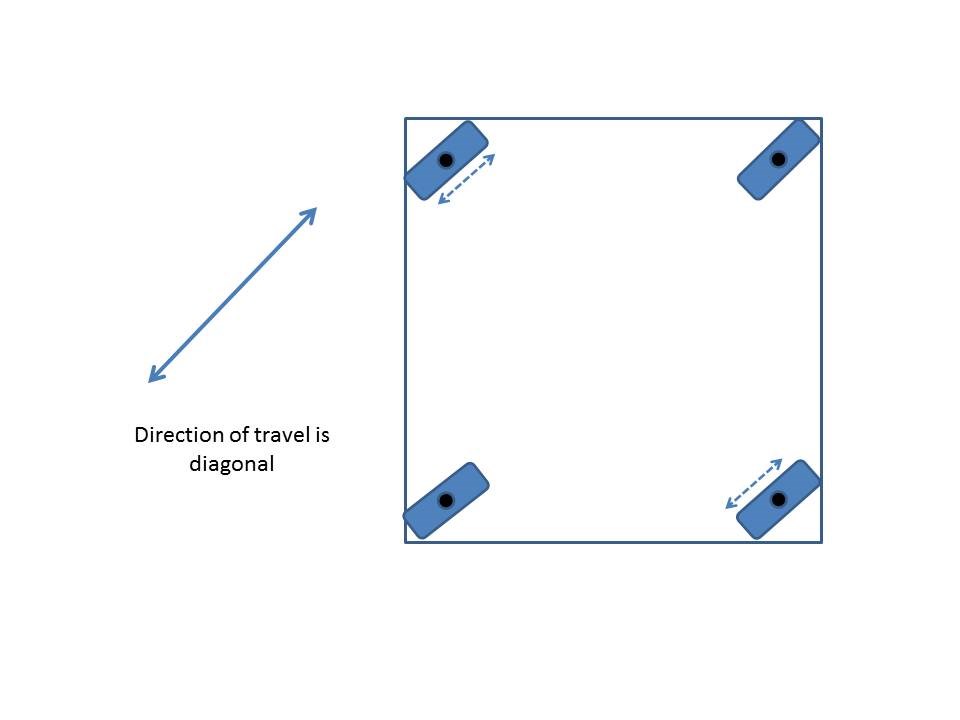
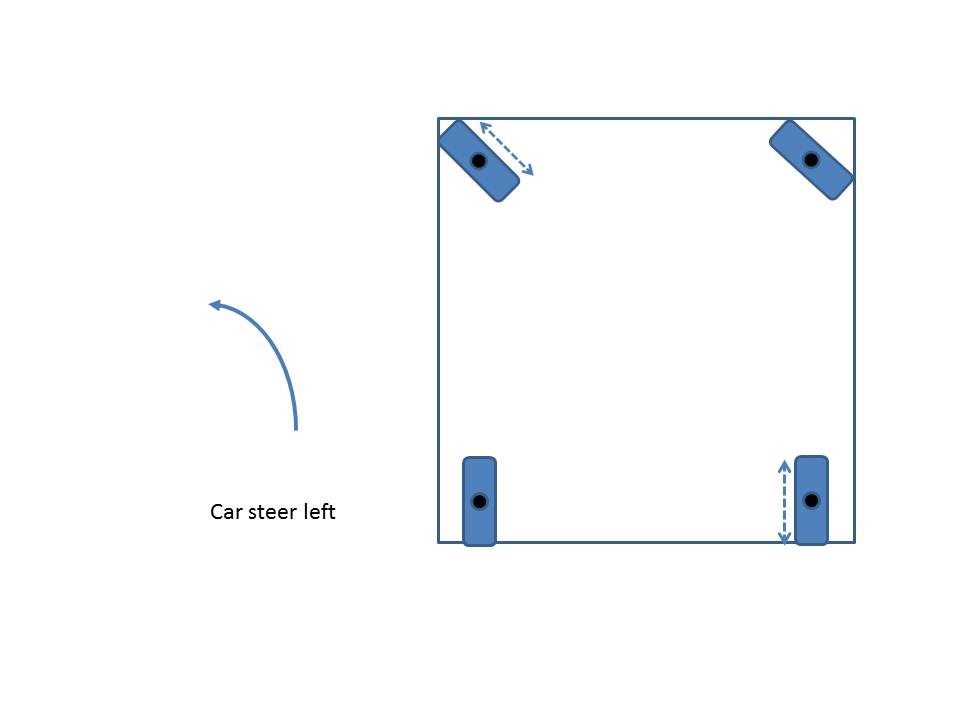
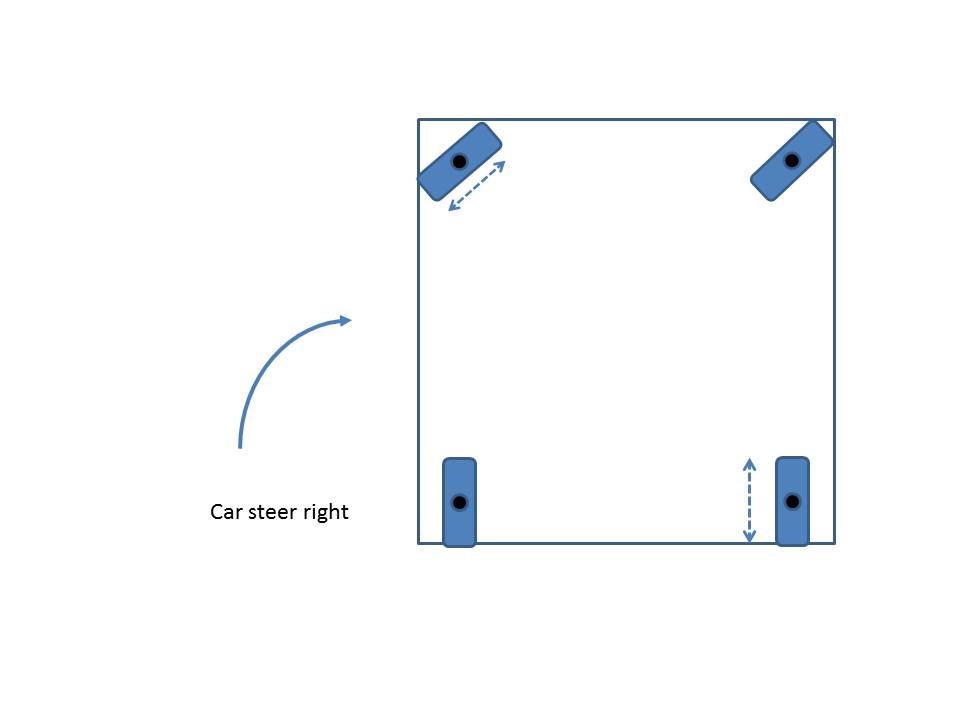
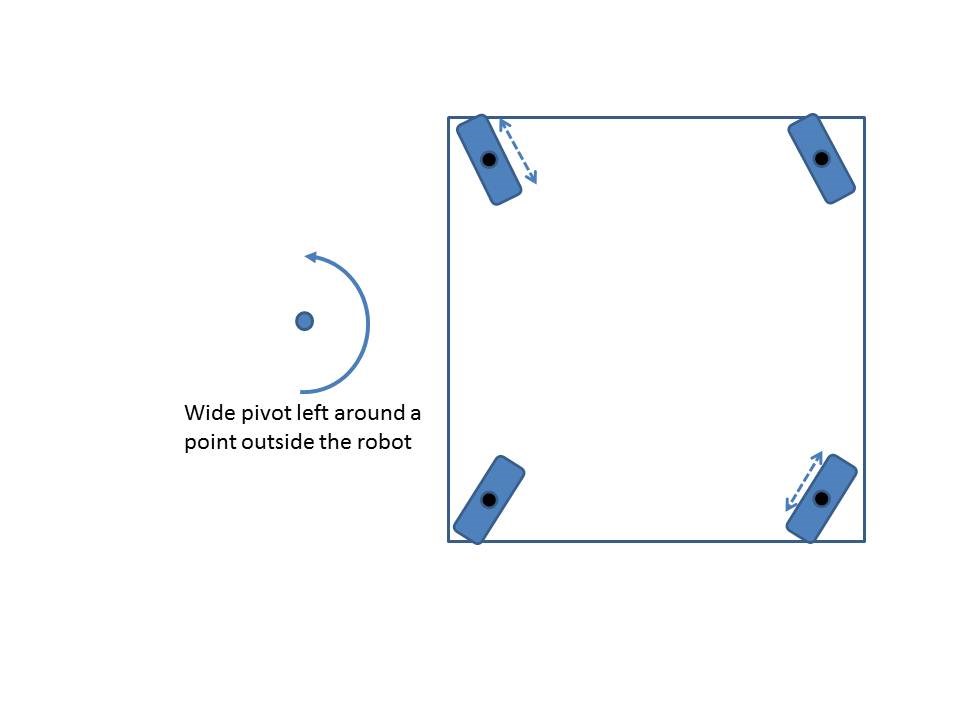
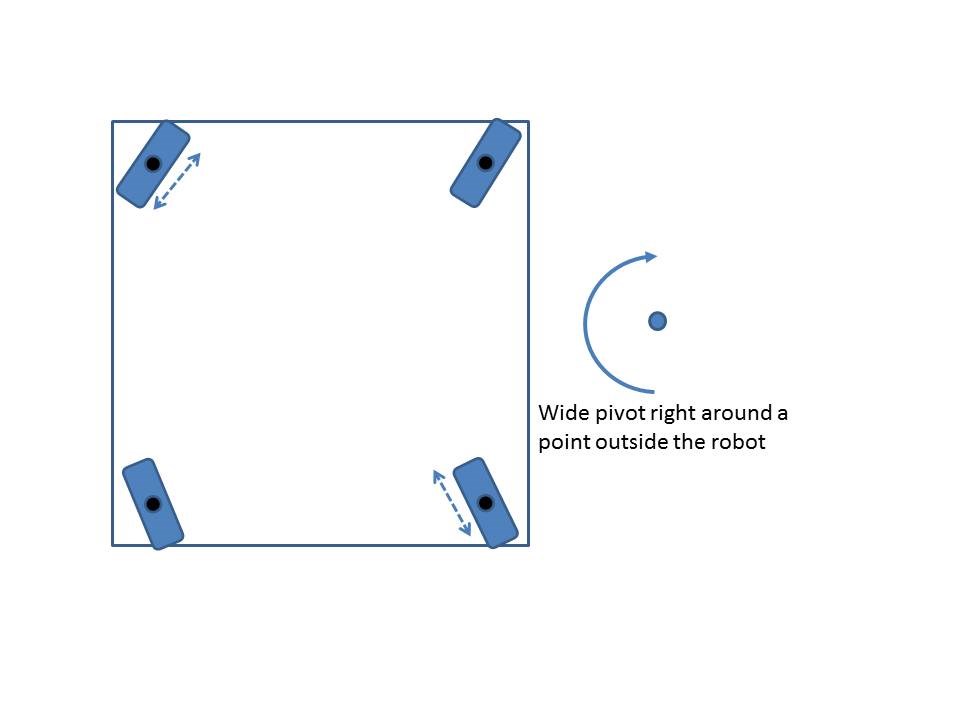
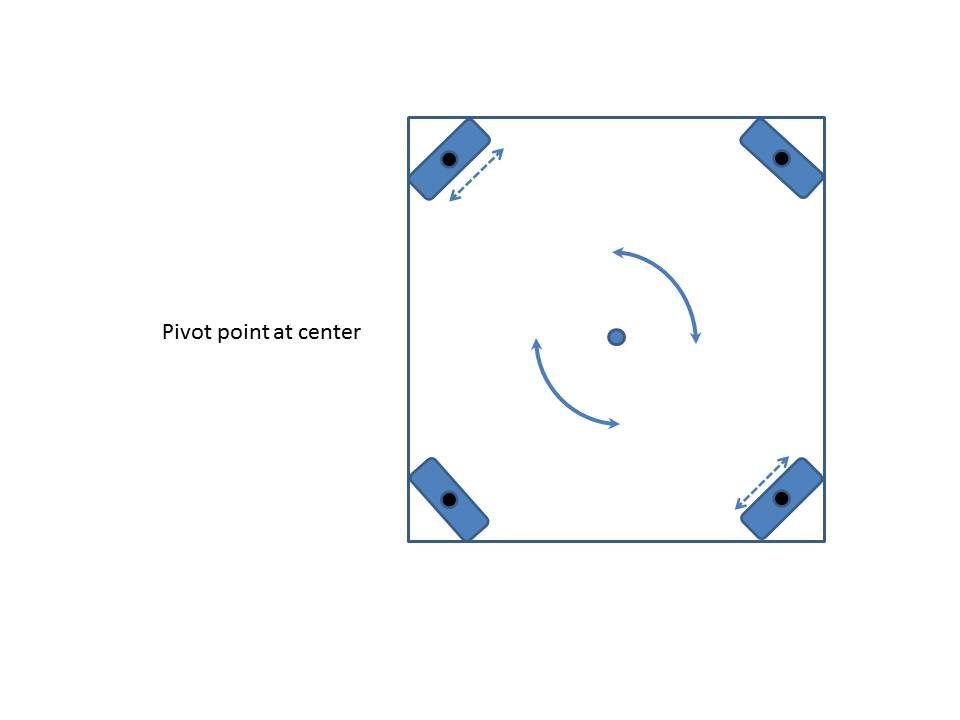
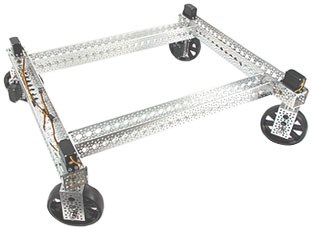
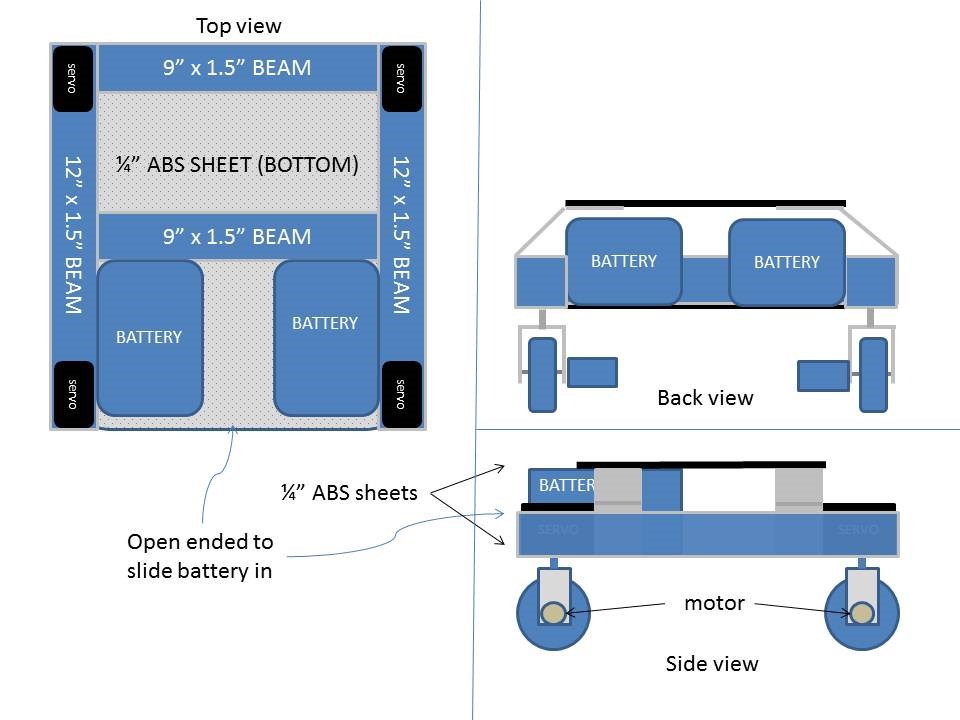
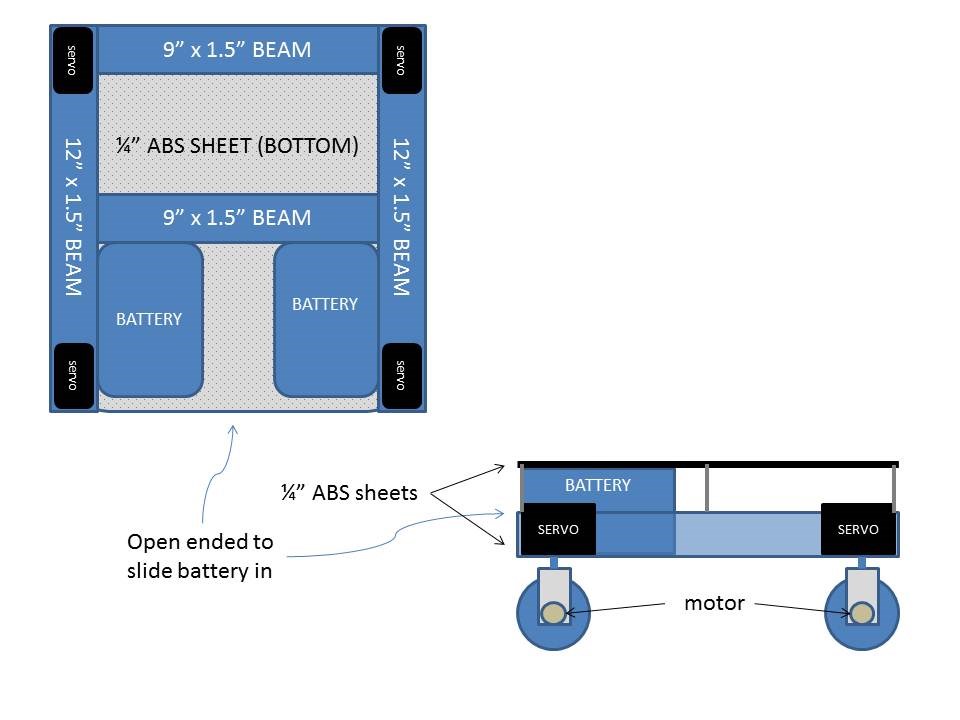
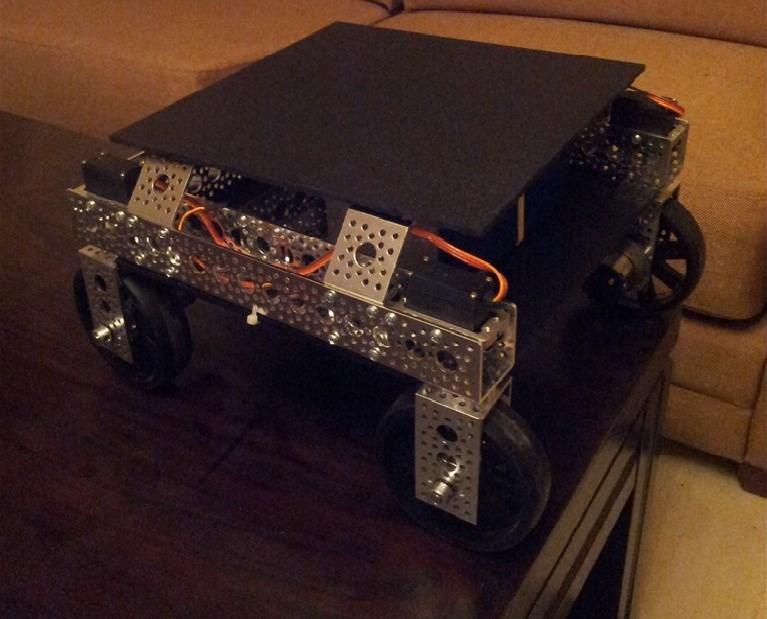
I'm at a crossroads on which type drive to use. Either the swerve type like pictured below or mecanum. The mecanum wheels I got imo are too big and may require higher torque gear motors. Which way should I go?
Yeah thats true but I wanted the movement to be different. I saw your thread using them and I like them a lot but they won't give me sideways movement though.
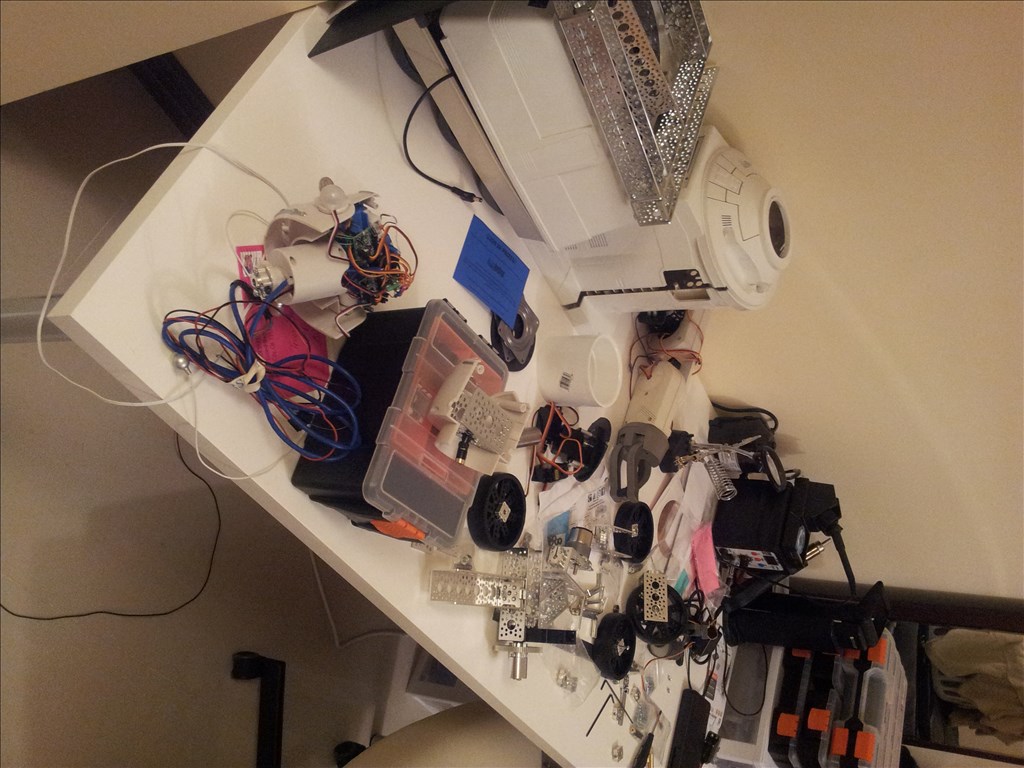
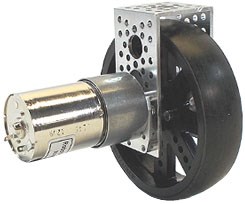
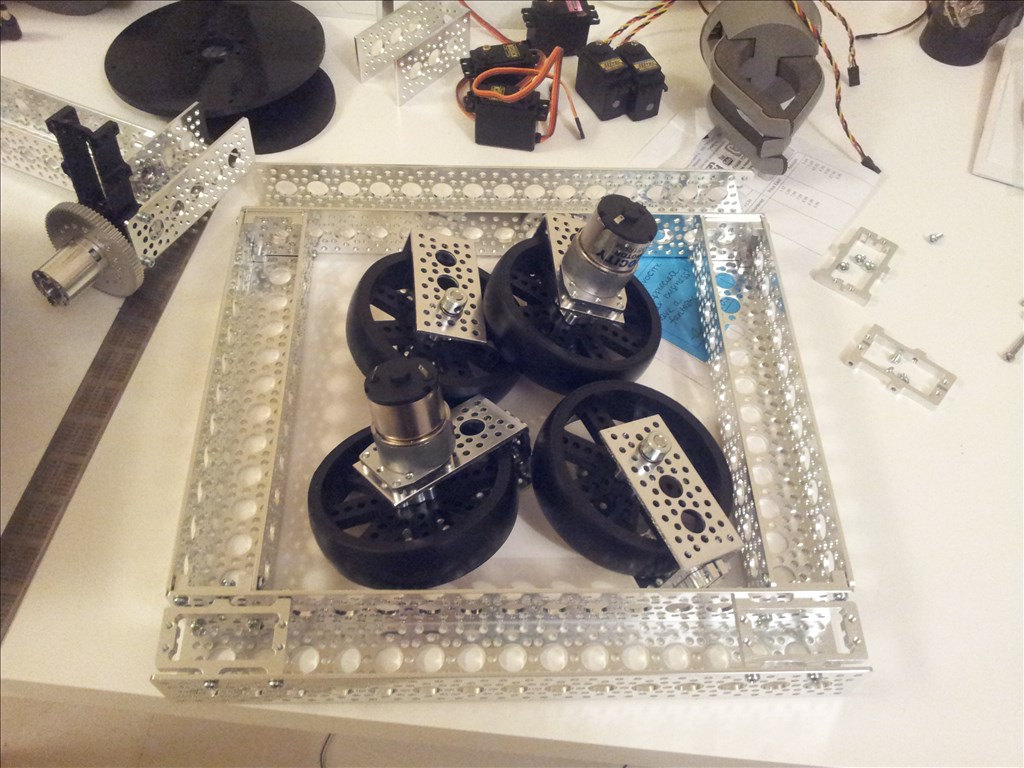
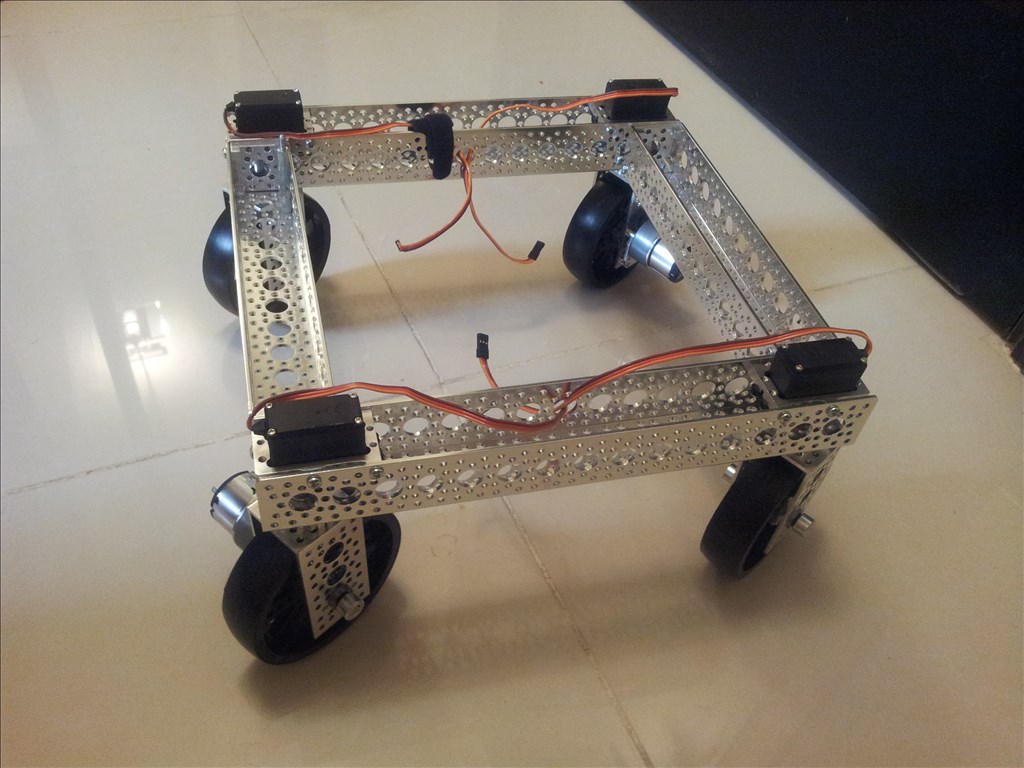
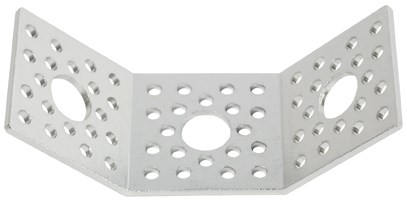
I've decided to go with the swerve on this one. I've already got most of the parts to do it. I just need the wheels pictured above and 2 more gear motor mounts. I will save the mecanums for a second bot.
Oh god. Where to begin?

(I dont know why my pic keeps getting rotated)