


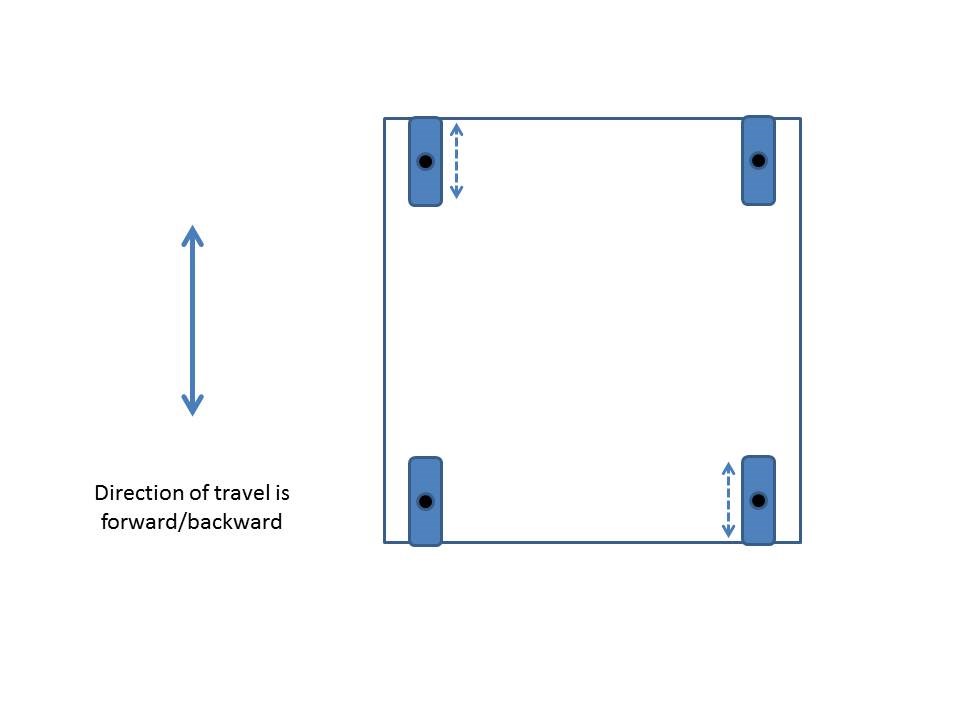
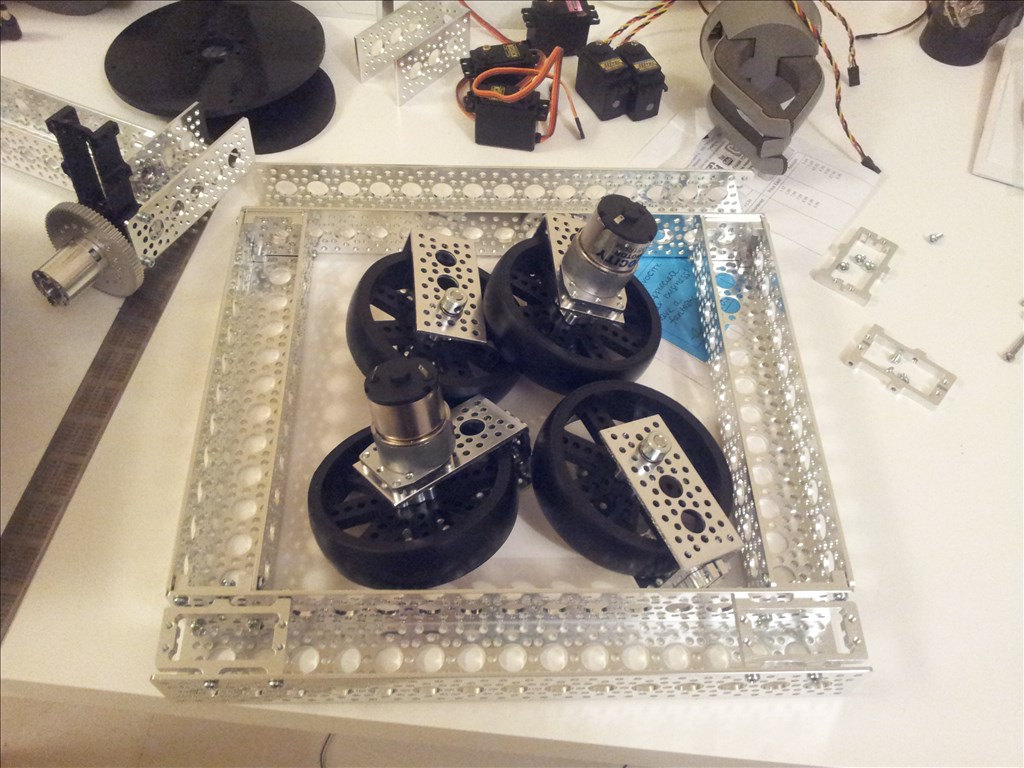
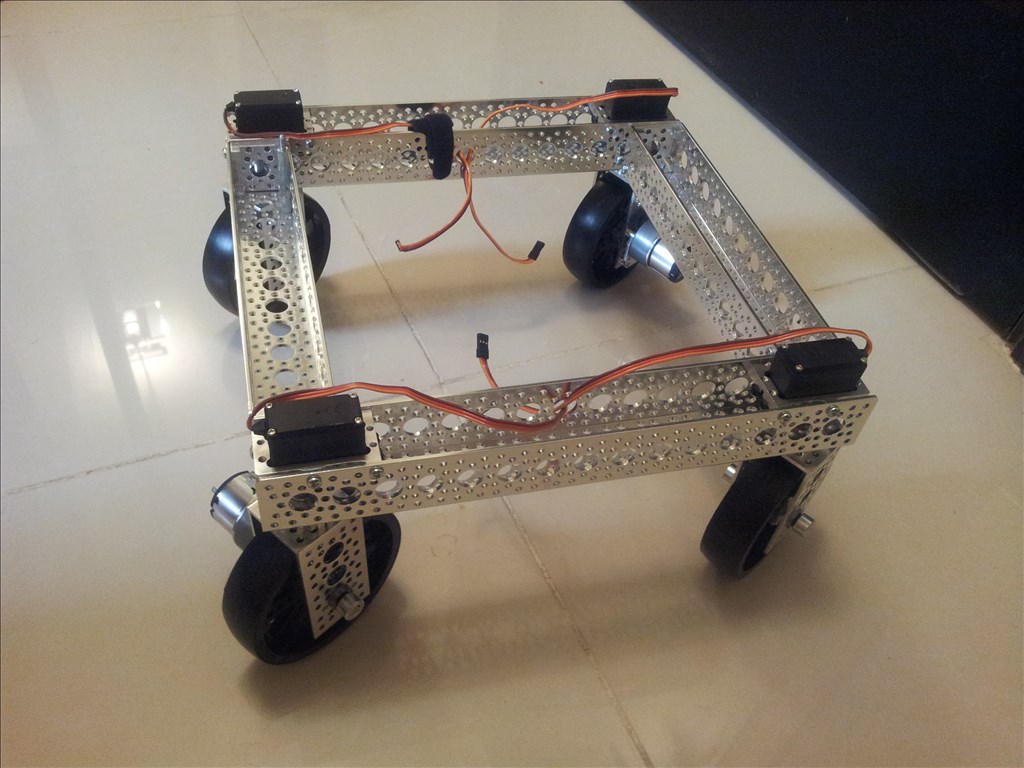
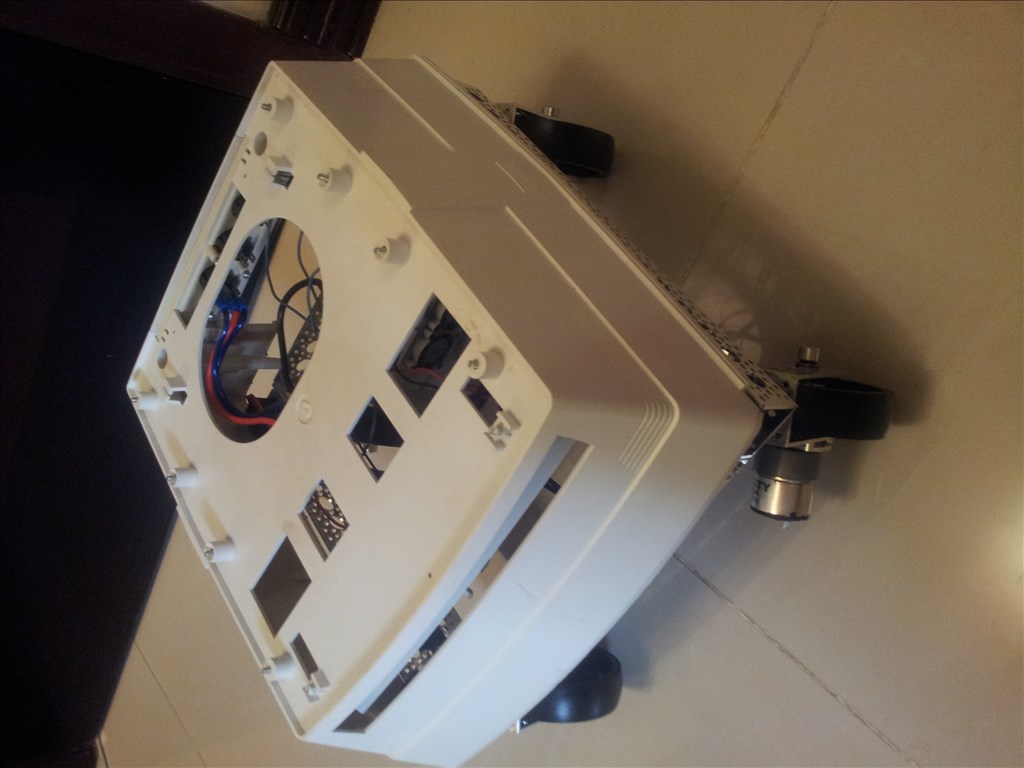
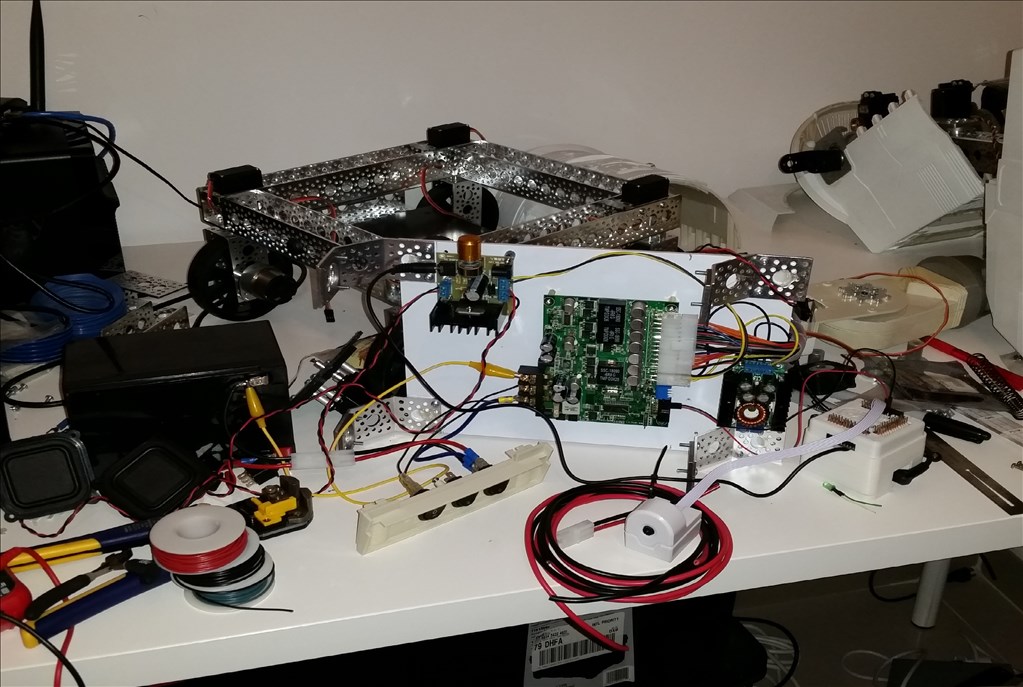
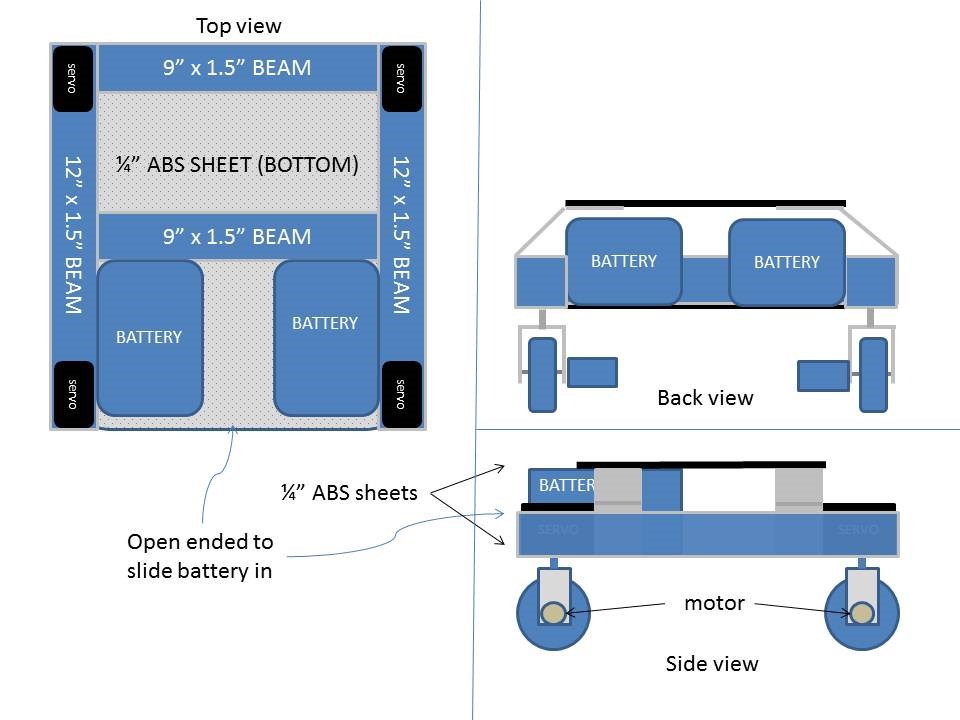
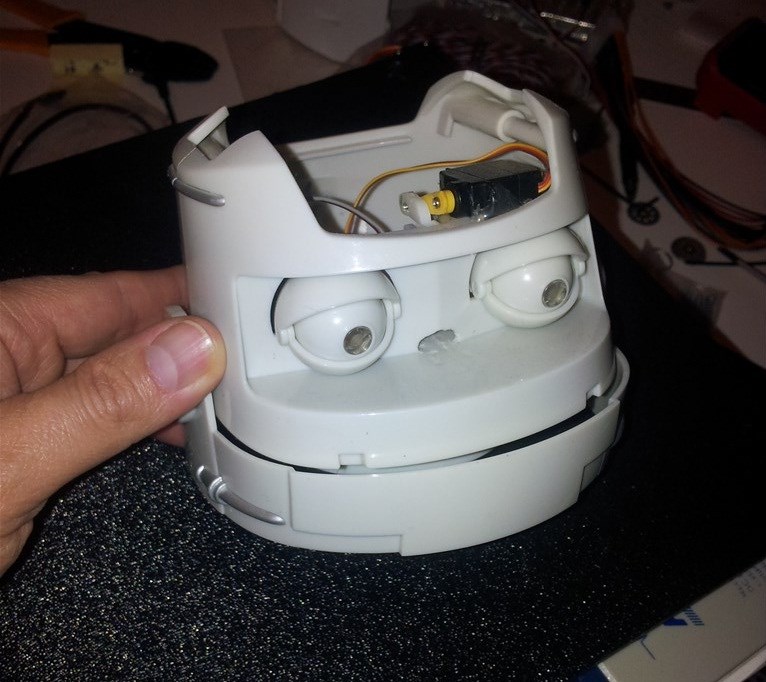
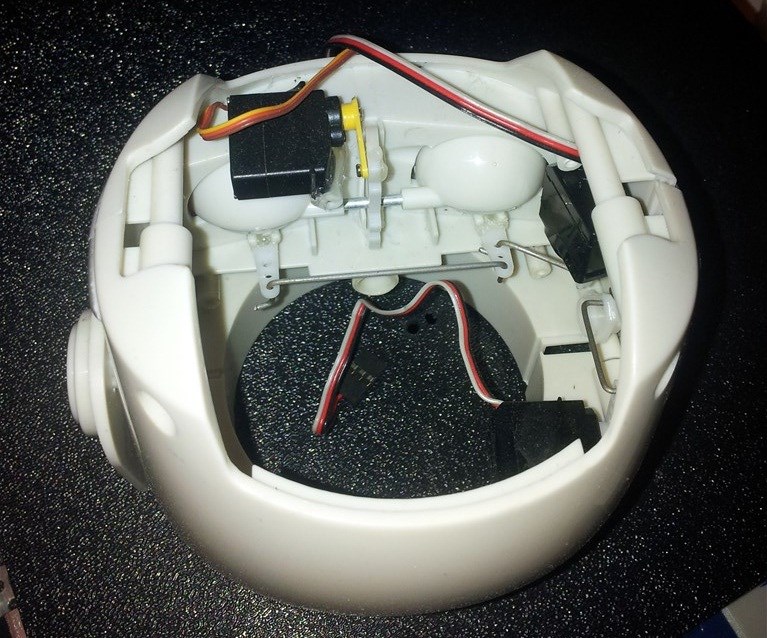
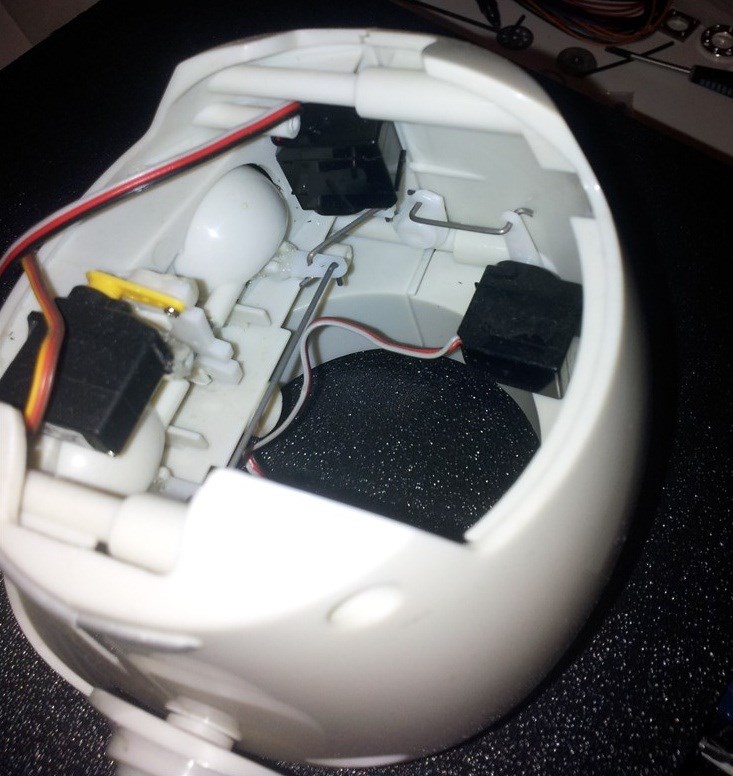
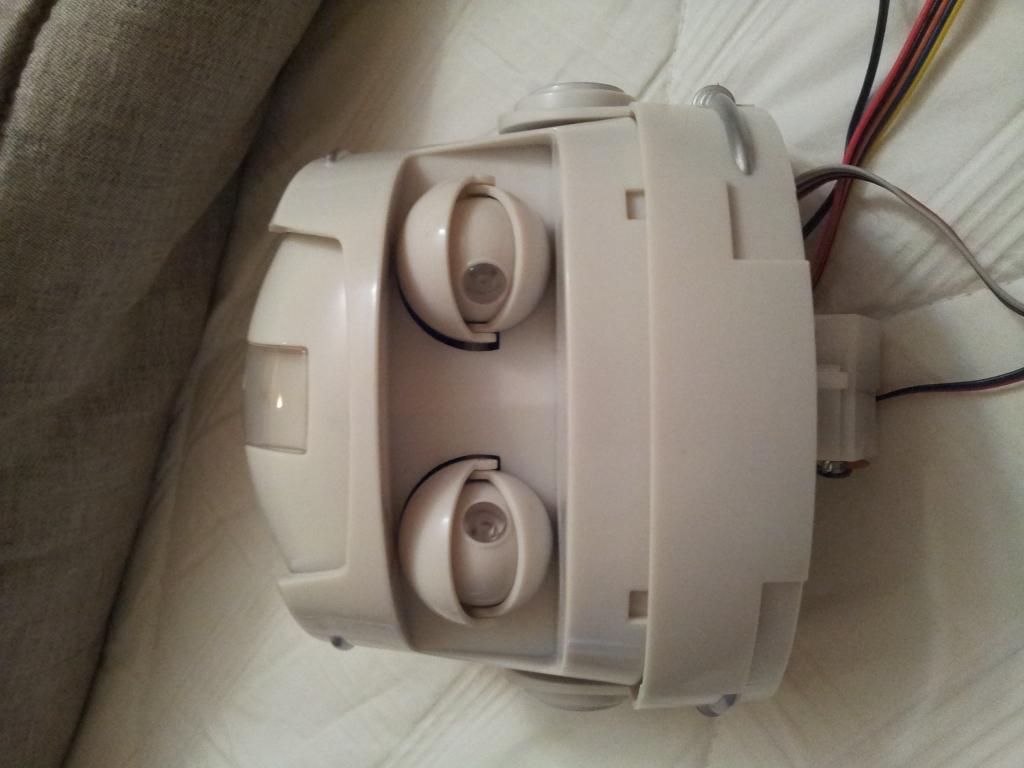
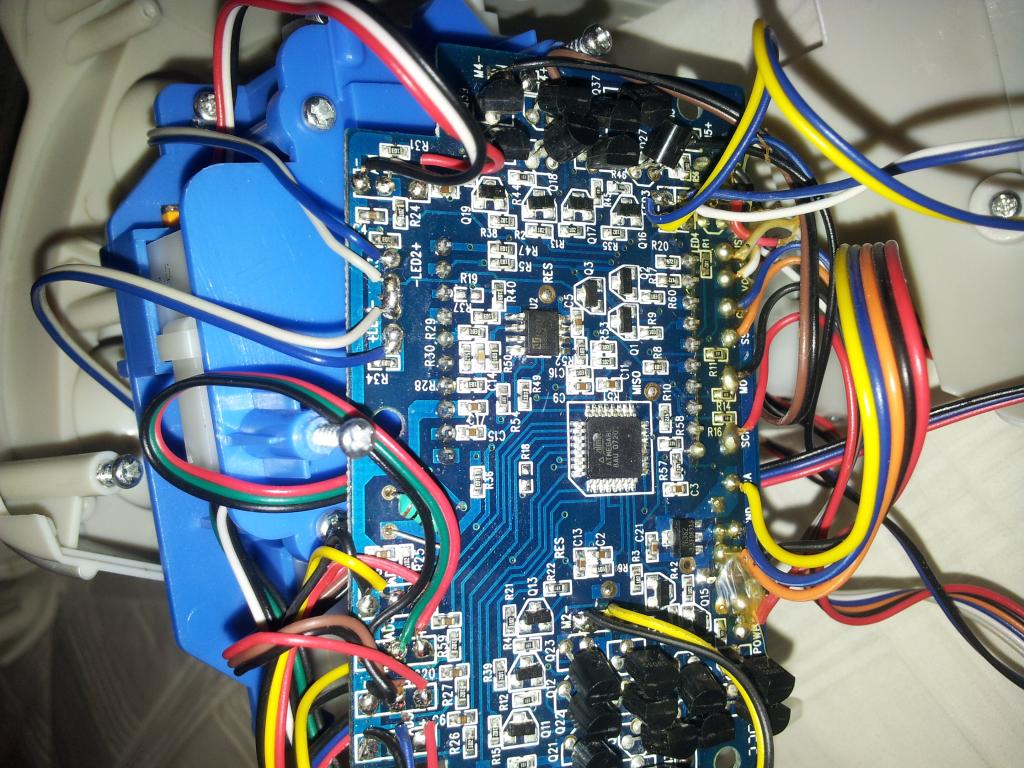
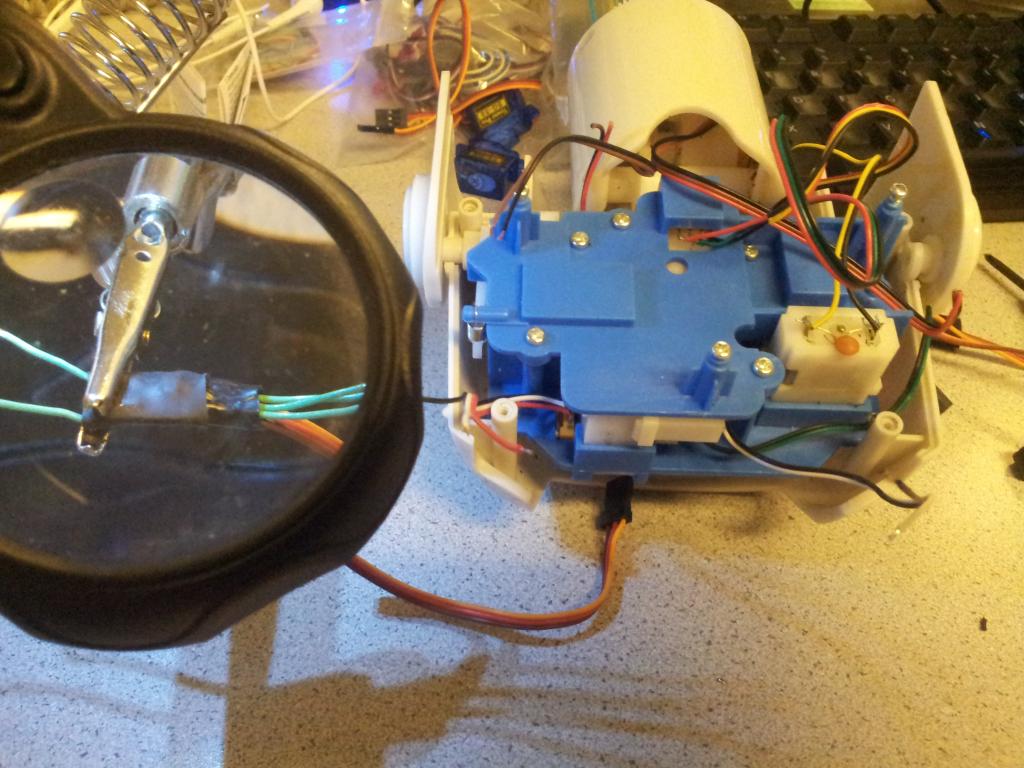
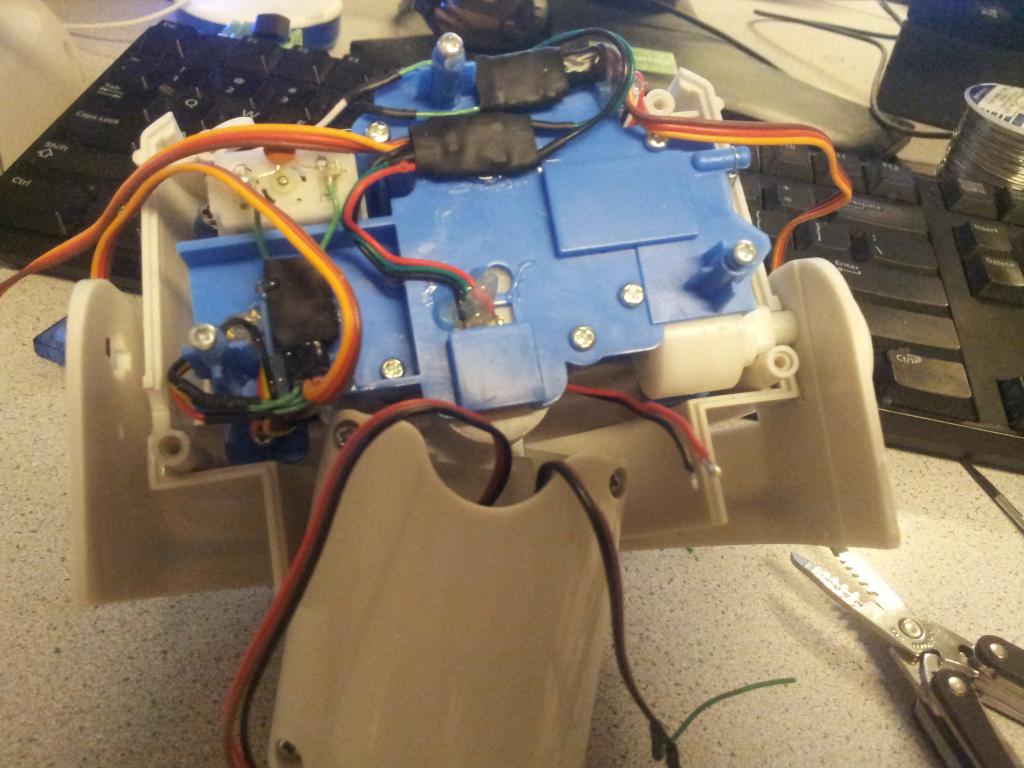
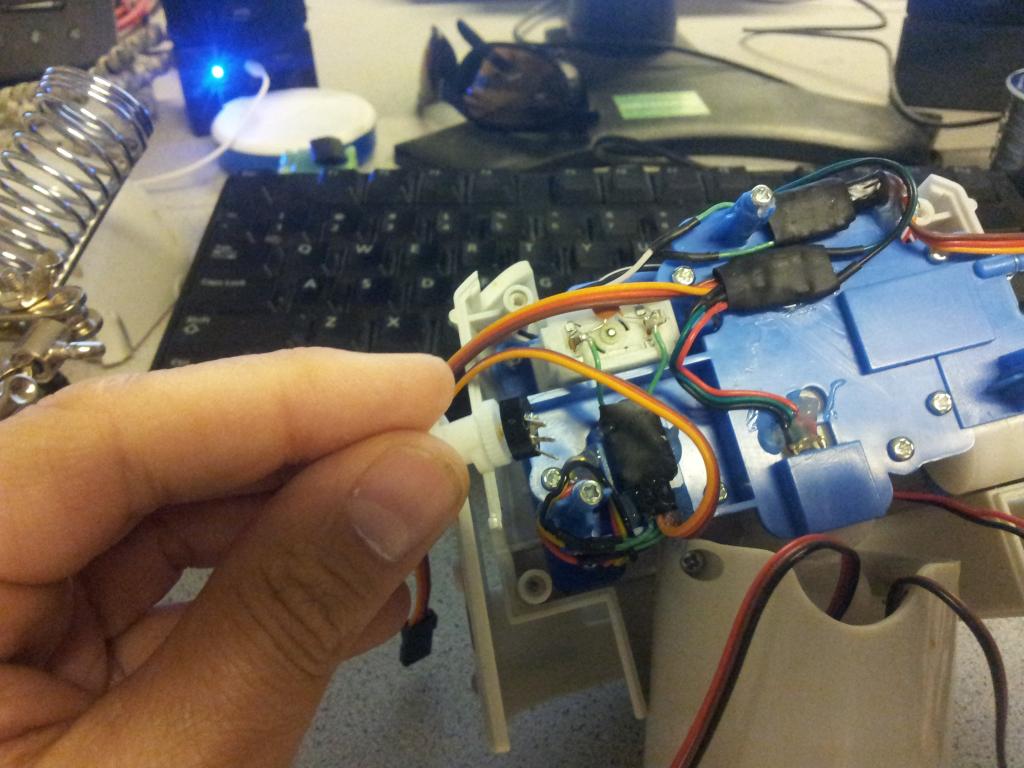
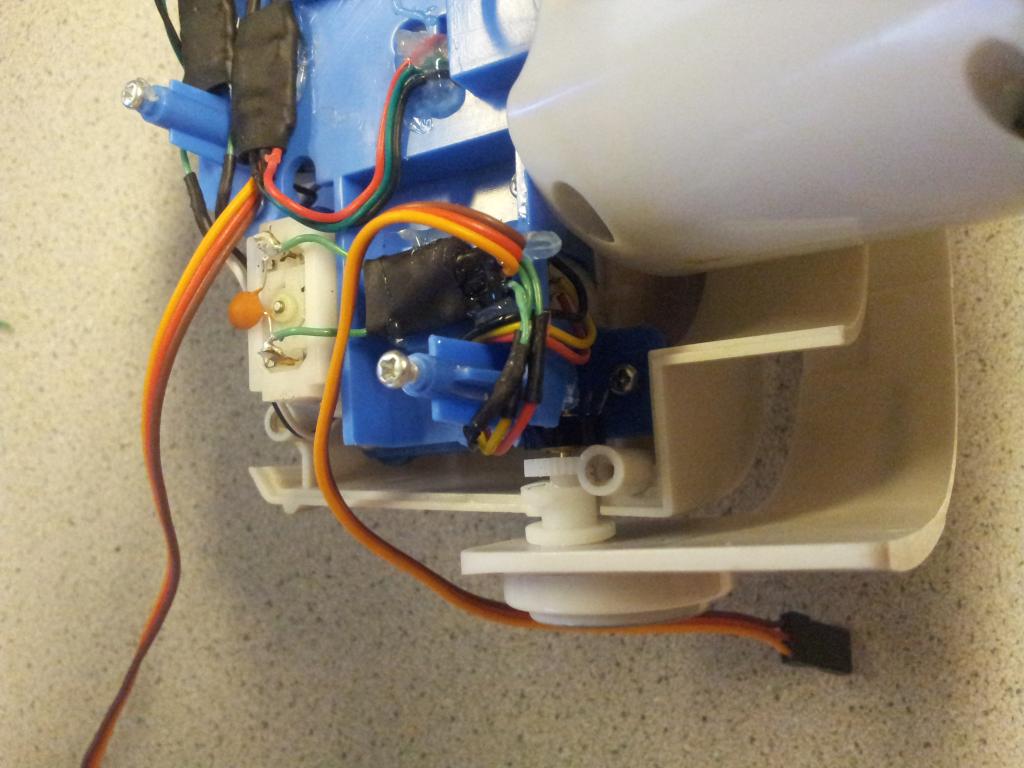
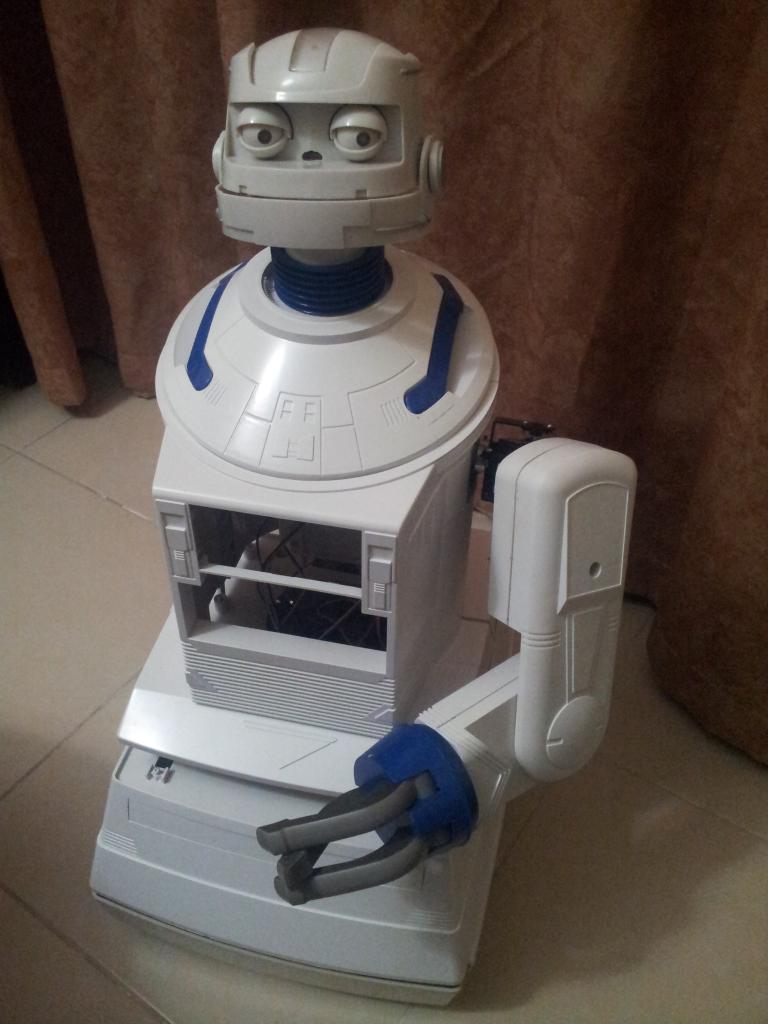
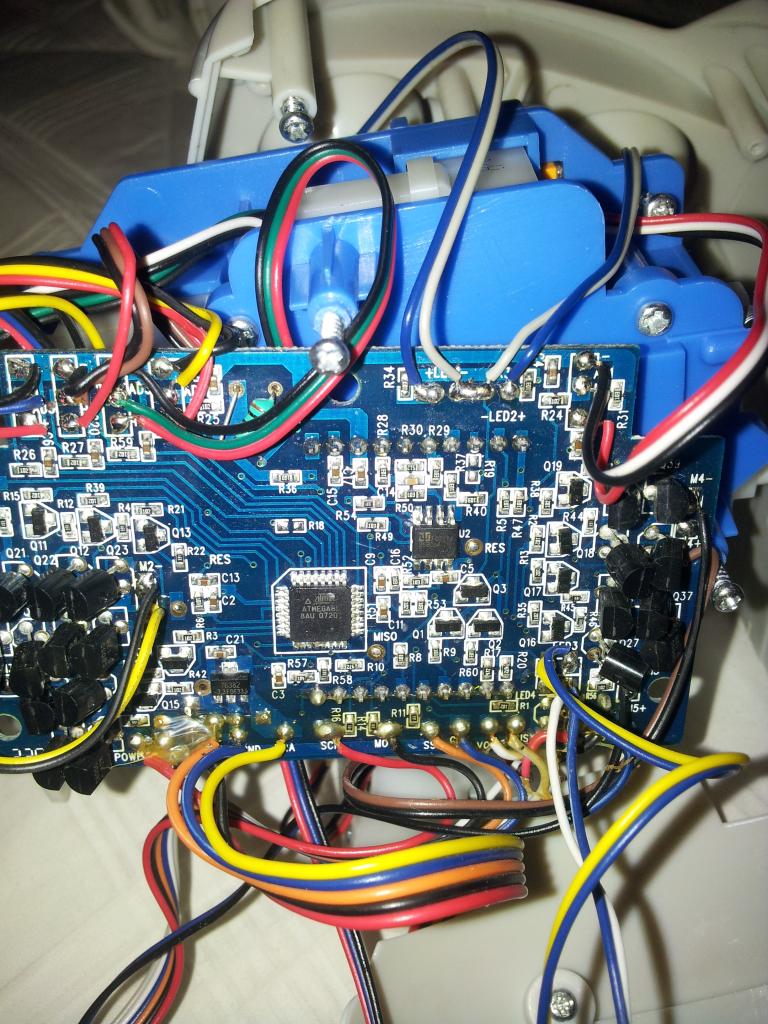
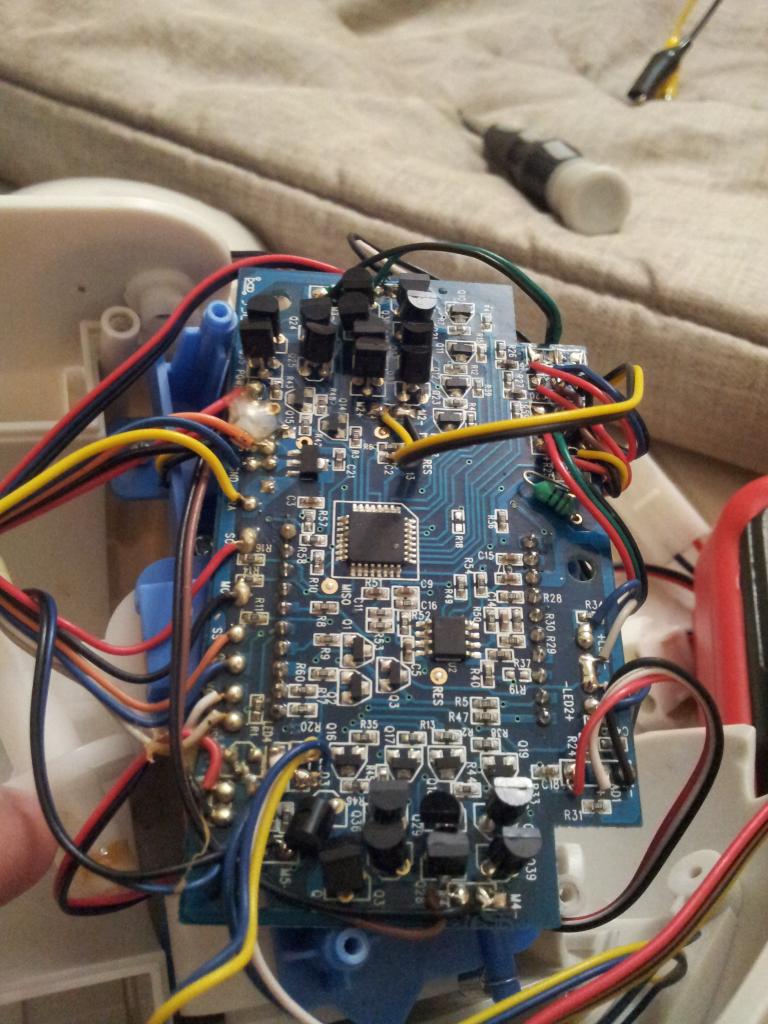
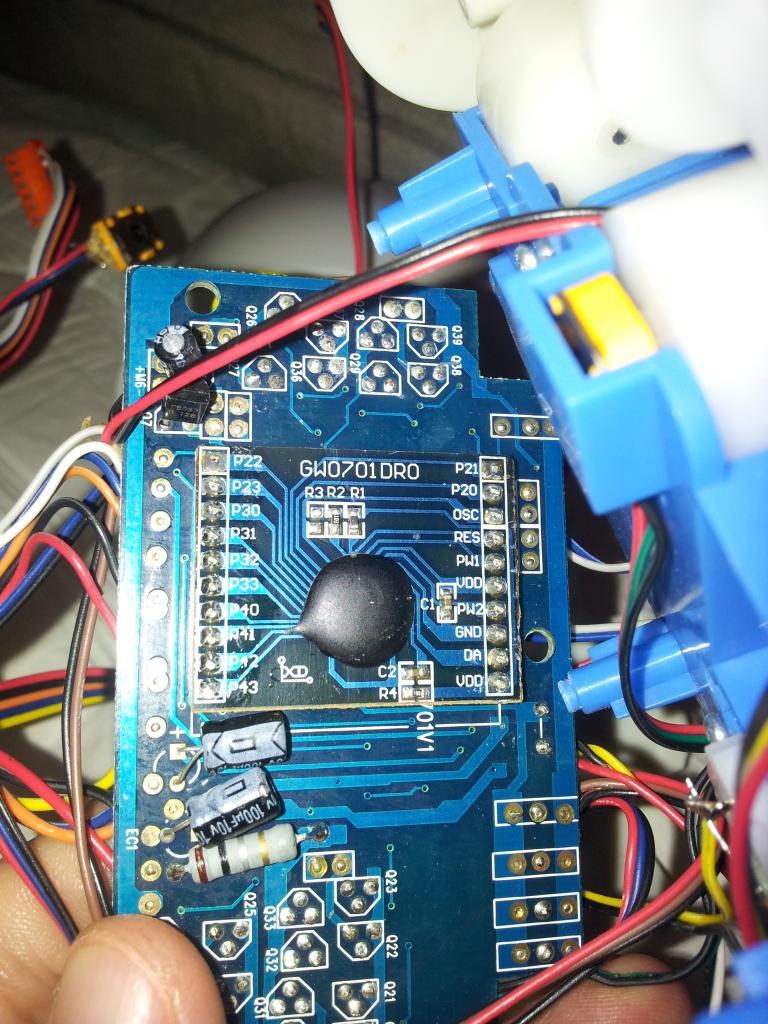
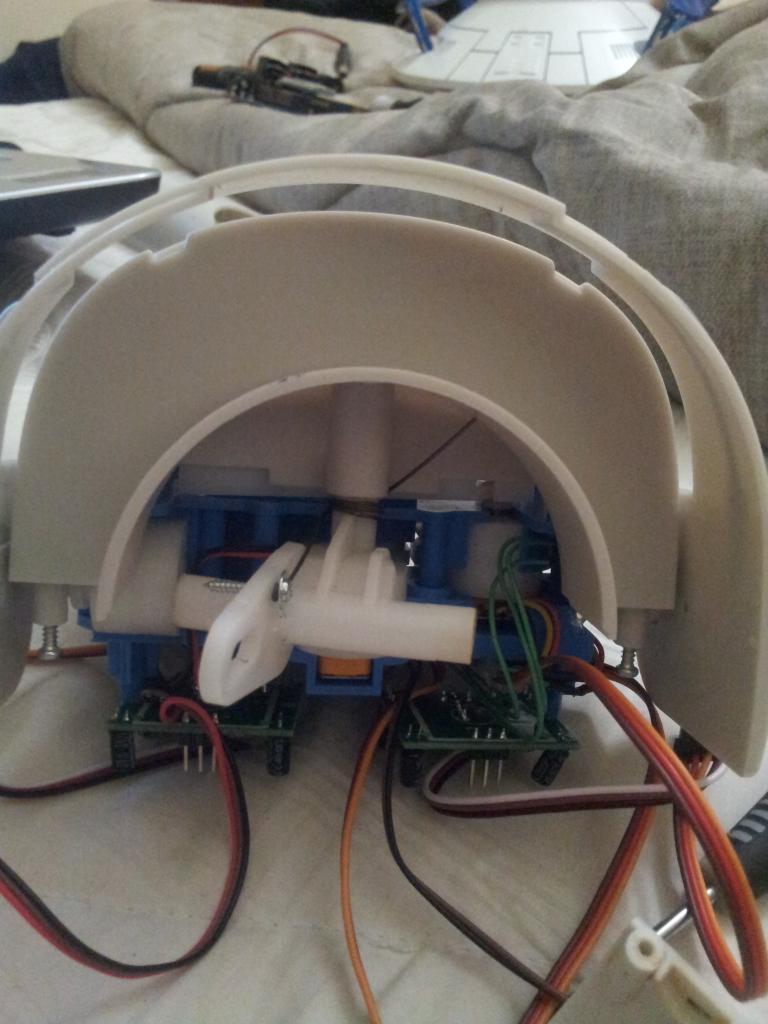
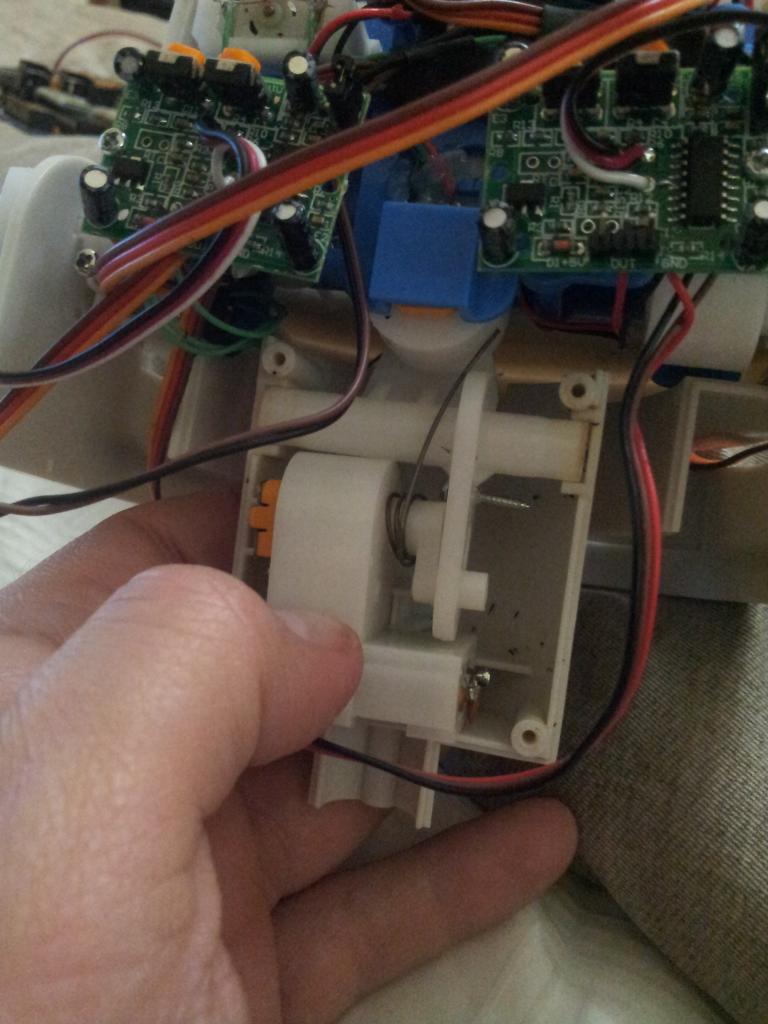
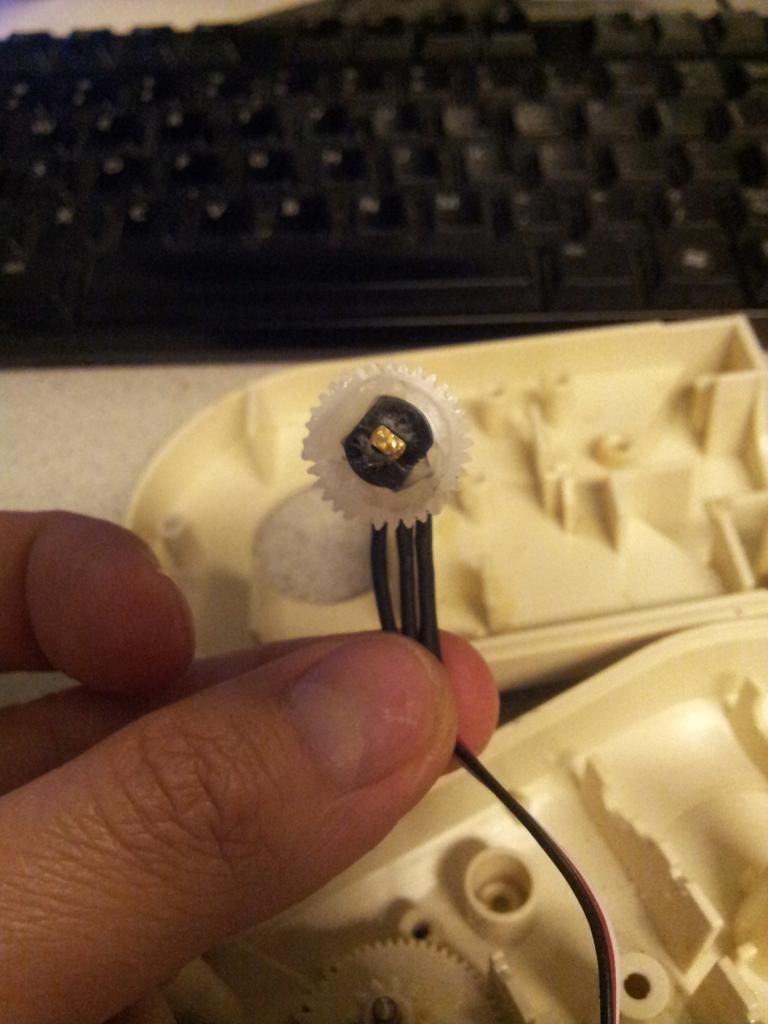
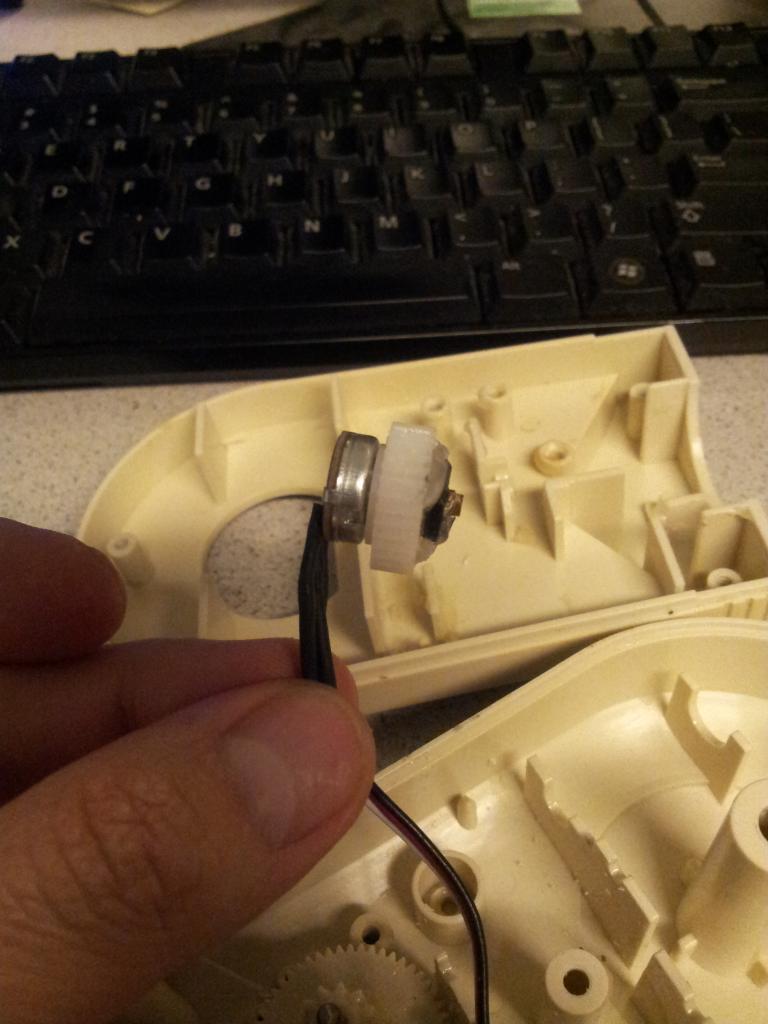
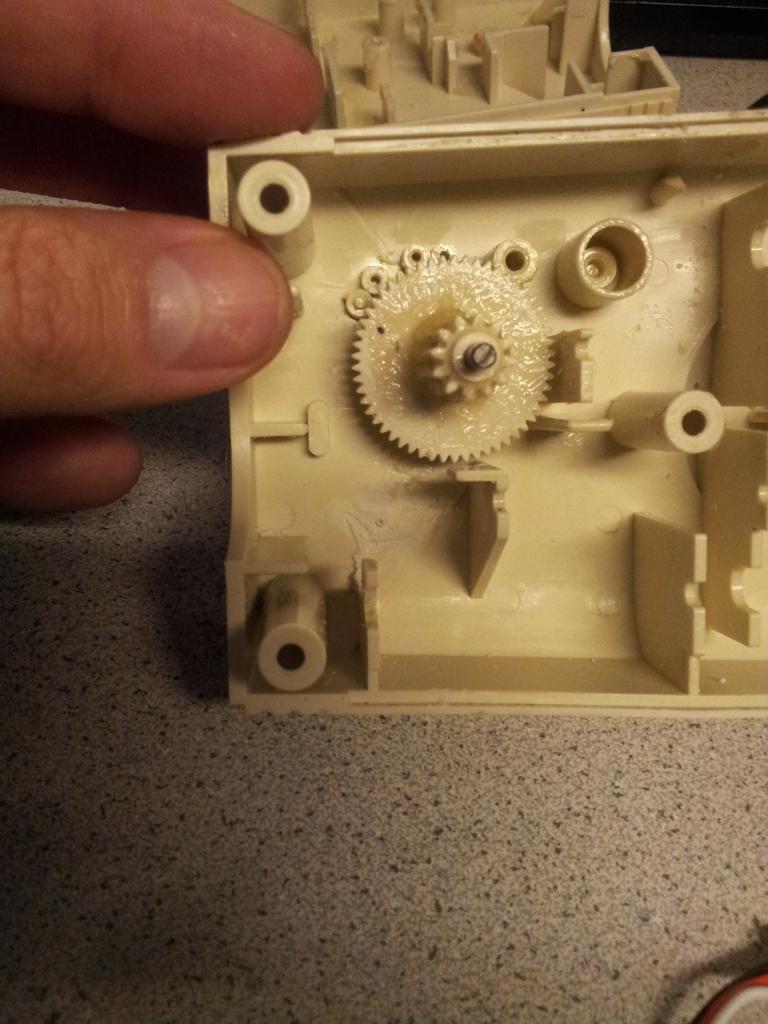
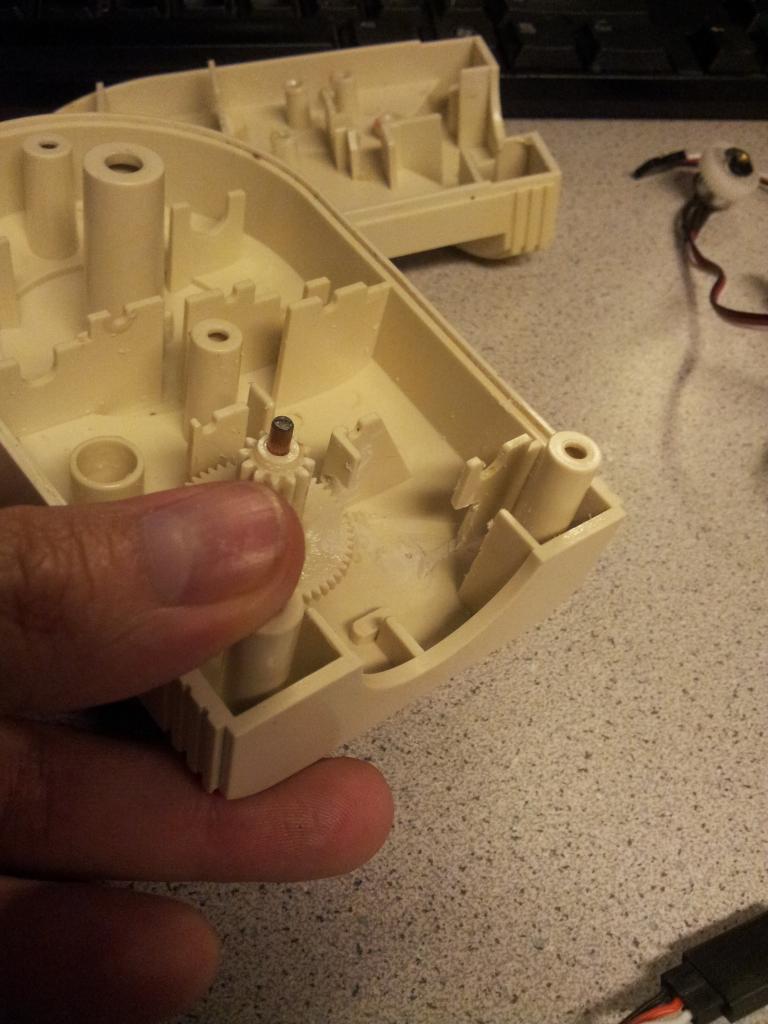
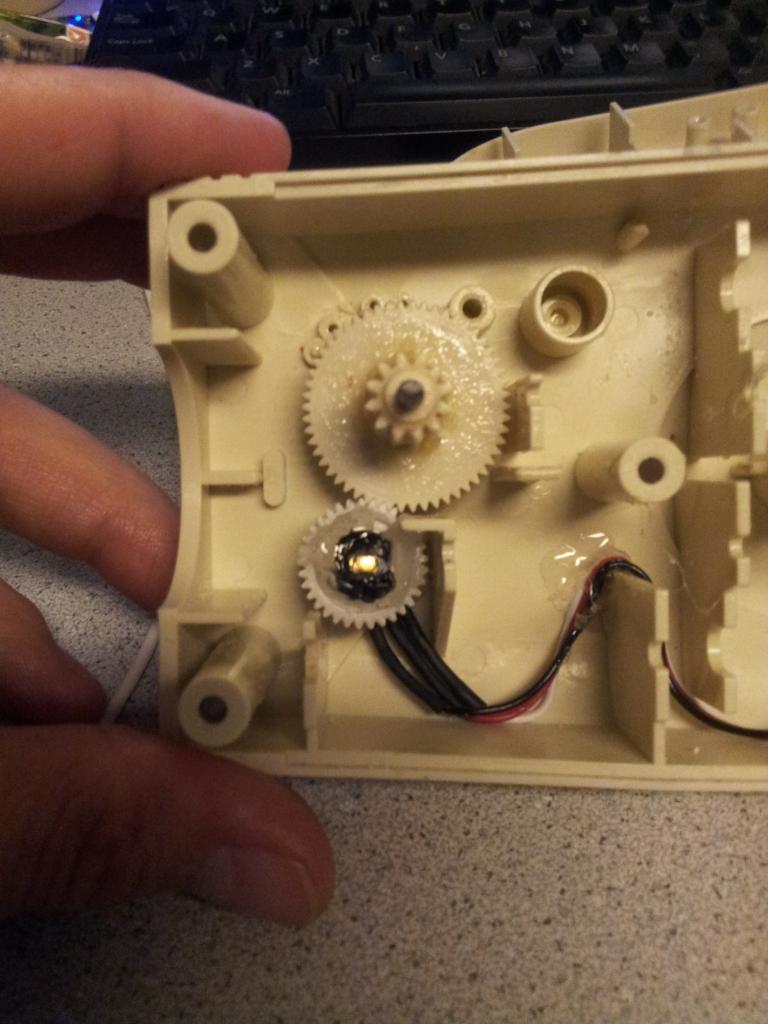
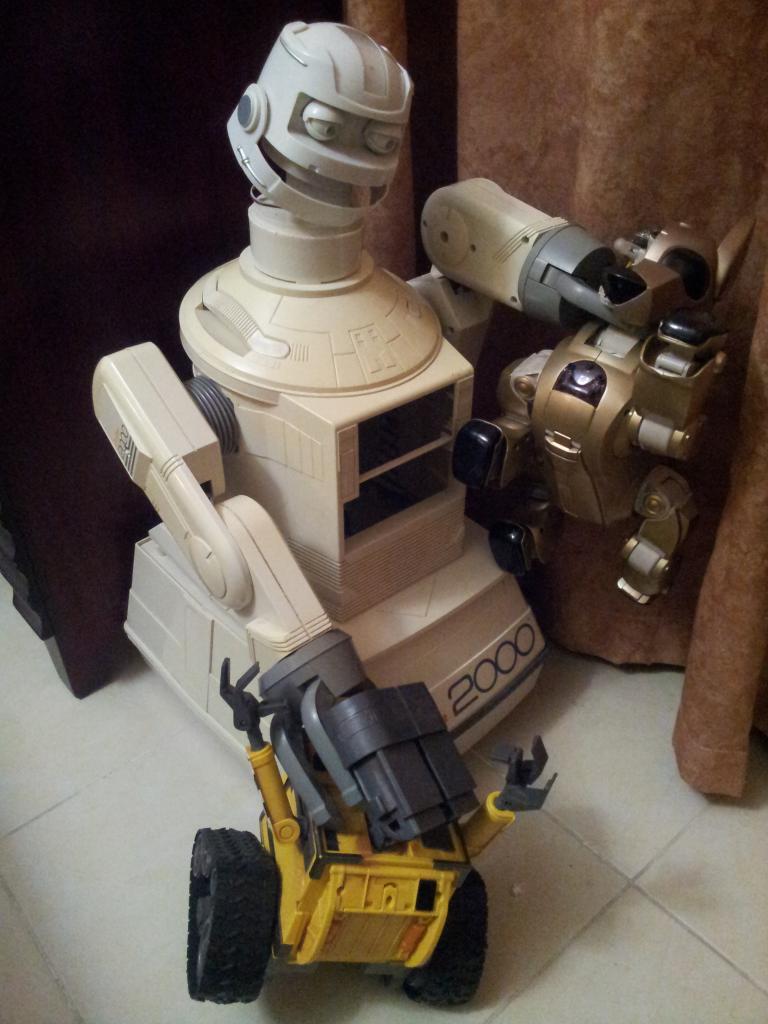
It's just a concept right now but I wanted others to see that the scale doesnt quite match. Right now its just stacked on there and neck is a little too long.
By Troy
— Last update
Discover more robots
DJ's Apple Watch Robot Control
Synthiam ARC adds Apple Watch support to the ARC iOS app, making the watch more useful and fun for ARC users.
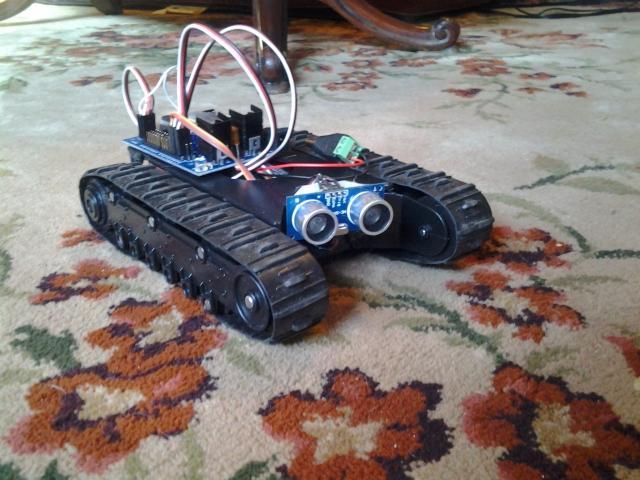
Ww321q's Testbot
Learning the software; experimenting now with plans to add camera and arm.
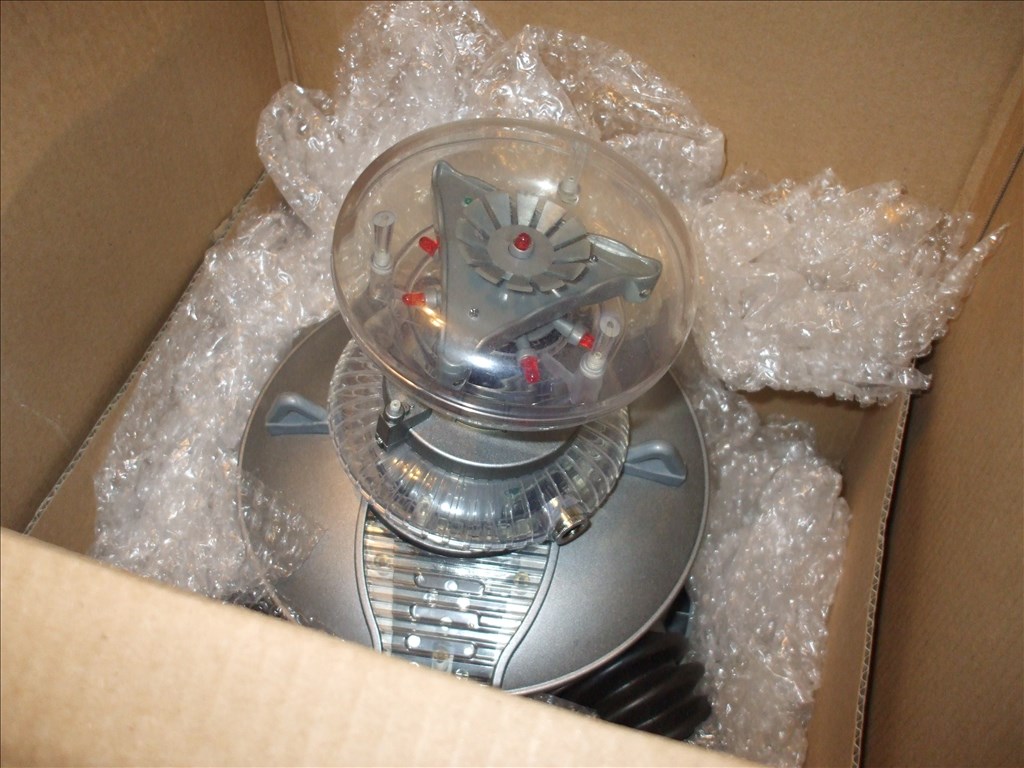
Justinratliff's Mini B
Mini B robot from Bret Tallent arrived damaged; repairing broken head, camera PCB, neck servo and right arm; RAD power...

I am just rolling my eyes! Great job.
sick blush eek J
Thanks guys! I hope more to come soon. No promises. Lol
@Troy no pressure! Lol
Hi Troy.. would you help me with some more specific "how to" use the head ? I saw in the early posts that you was able to use the native hardware.. how did you do that ? and saw later that you took off all the pieces and put some microservos.. Was that a better solution ?
thanks for all your help!
@tevans, Yes it was better in the long run. There was too much looseness in the neck gears. You can see that in an earlier video. I tried tightening it up with some springs but really it was better for me to replace it. It is also less work than making those servo boards. Also, I freed up more space inside for other things if I decide to use it later. Good luck to you!
LOOKIN' GOOD MY FRIEND!
Hey Troy,
Wow, it took me a little while to catch up. I am so glad to see that you are still working on pinhead. :o)
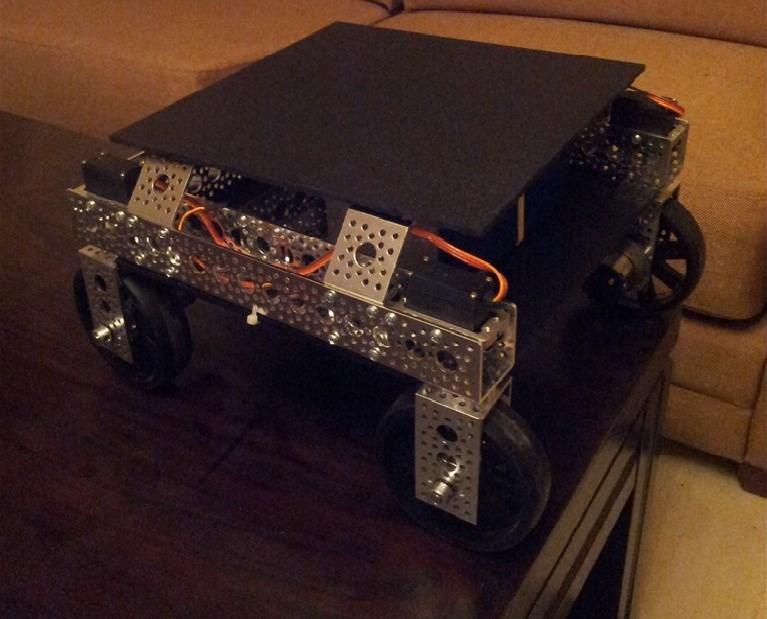
That base looks nice and light wright.
How are things?
heh Pinhead has been on hold again. I still think of new things though.