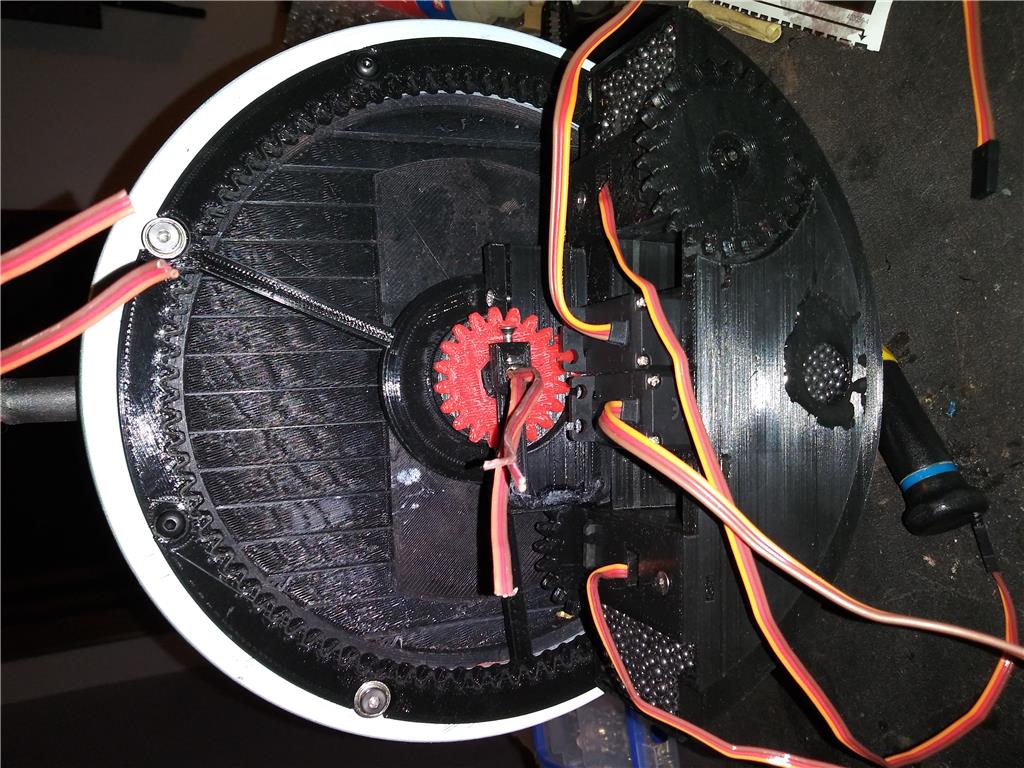
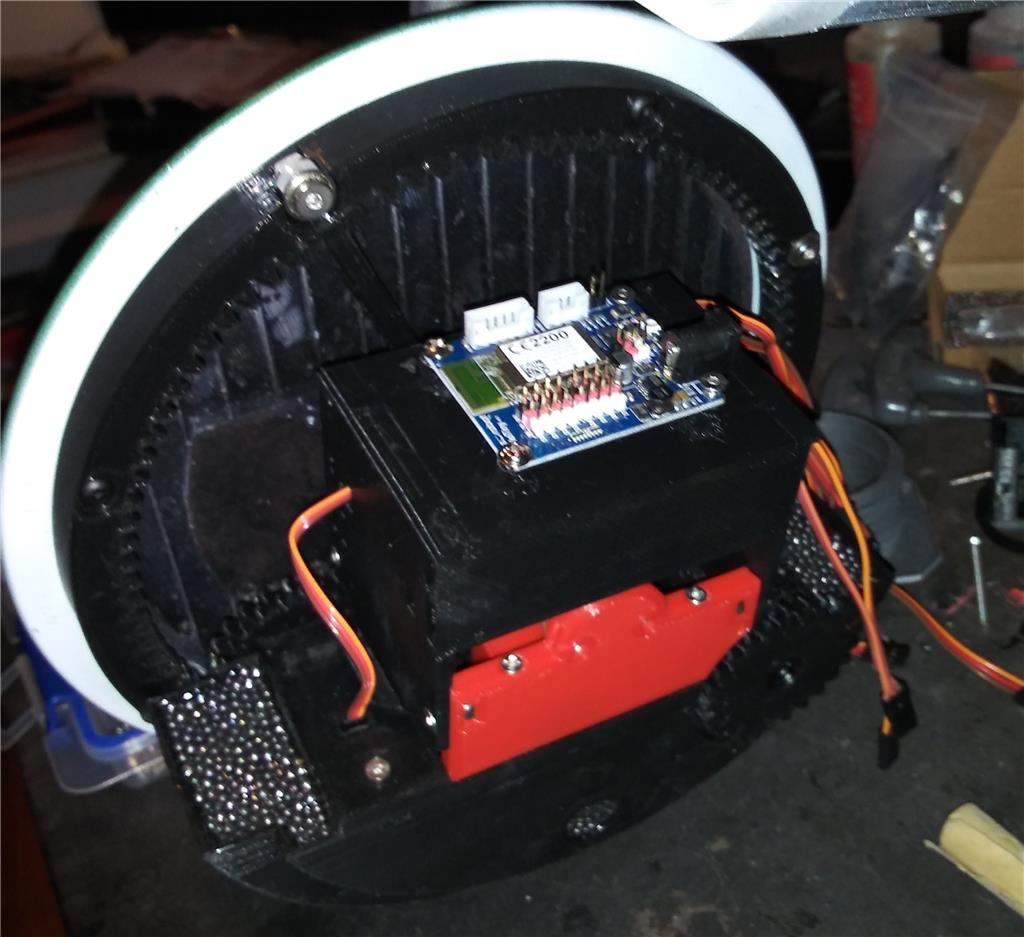
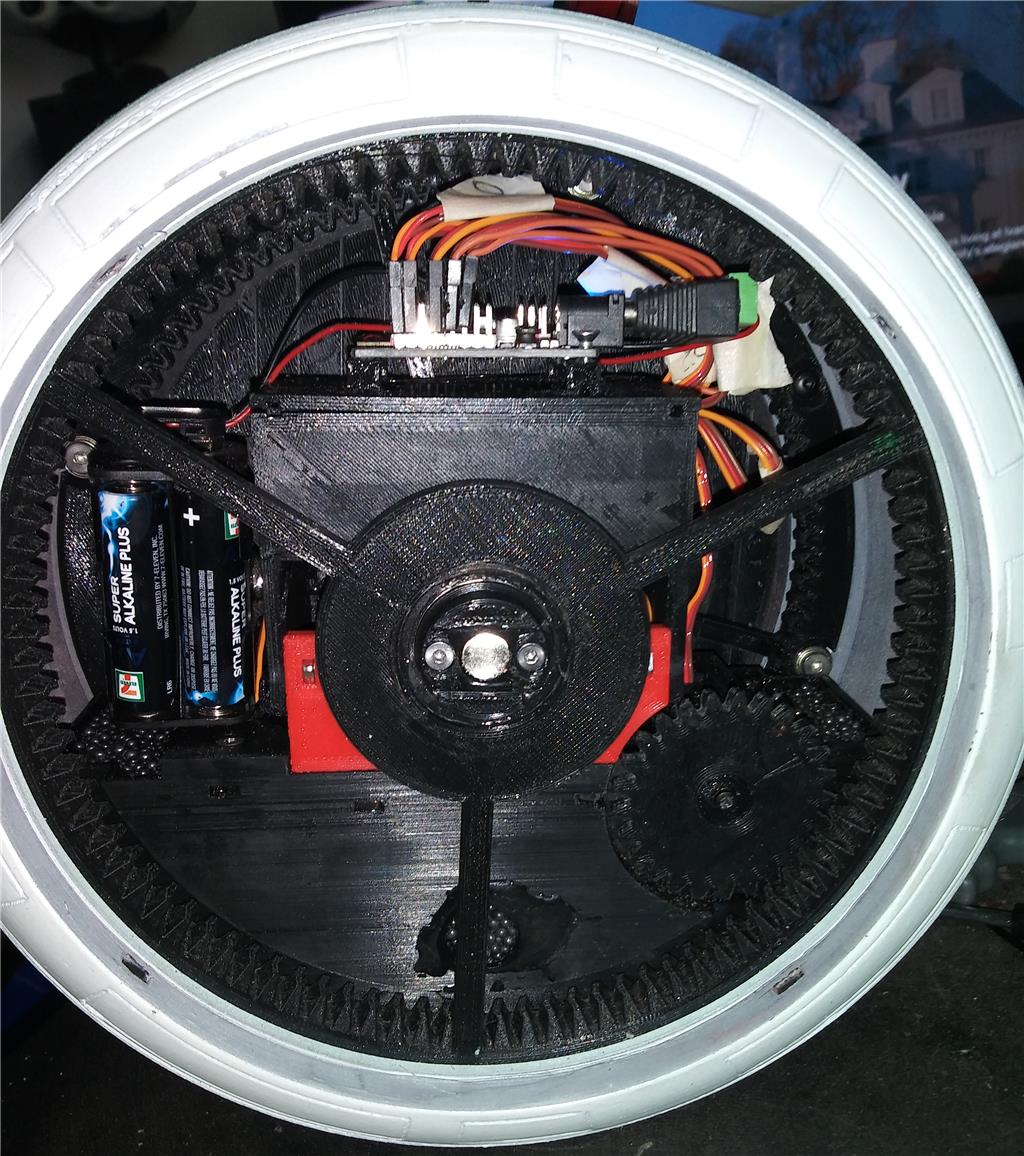
Here is my D-O droid powered by the IoTiny and controlled through my tablet.
The head is too heavy for the servo in the body, it wants to tilt forward so the nose hits the ground. so I had to lock it up. Otherwise it has the function for the bar holding up the head to tilt back and forth.
By kashyyyk
— Last update




Discover more robots
Robotz012248's Project Gizmo Underway!
Project Gizmo robot build converting a kitty igloo into multi-deck robot with motors, casters, threaded-rod decks and...
Tmesserschmidt's The Vision (Marvel) Robot Replica
Build a Vision robot replica using a mannequin, Vision costume, hacked Elvis bust, servos and an EZ-B; fitted costume...
Keithjmoore's My First Robot
iRis telepresence robot: a first DIY build in progress to serve as a telepresence platform for work.

Wow! That's a 3D printing masterpiece!
That is so flip'n cool!
WoW is Right. What are you using for the counter weight. I think it looks like shot. Maybe you just need more counterweight to compensate for the Head weight. if you do not have enough room try making a solid lead weight. Have you thought of a GYRO. for balance. Thanks for showing the insides.
It has about 4 pounds of shot. The head rod is connected to a servo to tilt it back and forth, the red gear in the first image, the counter weight doesn't affect the head, only keeps the whole assemble from spinning.