
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.

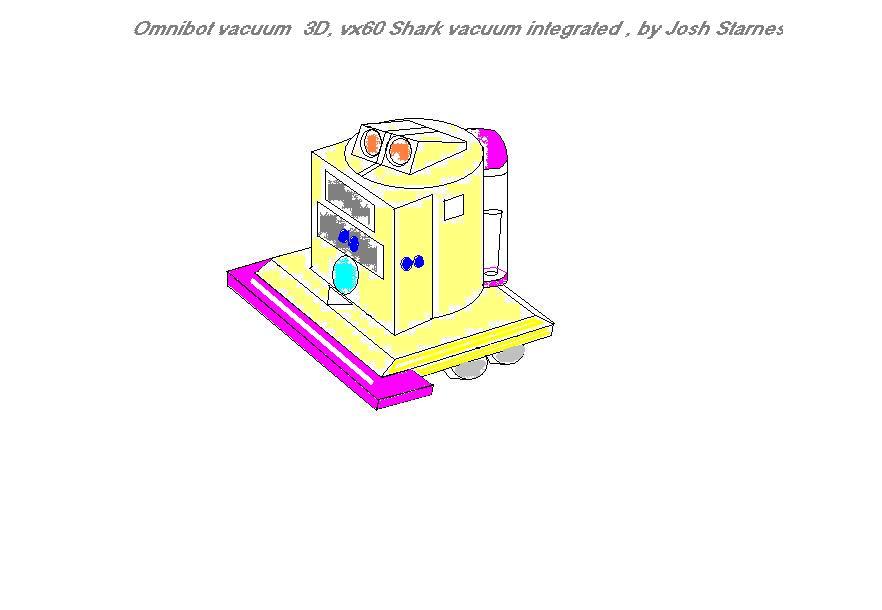
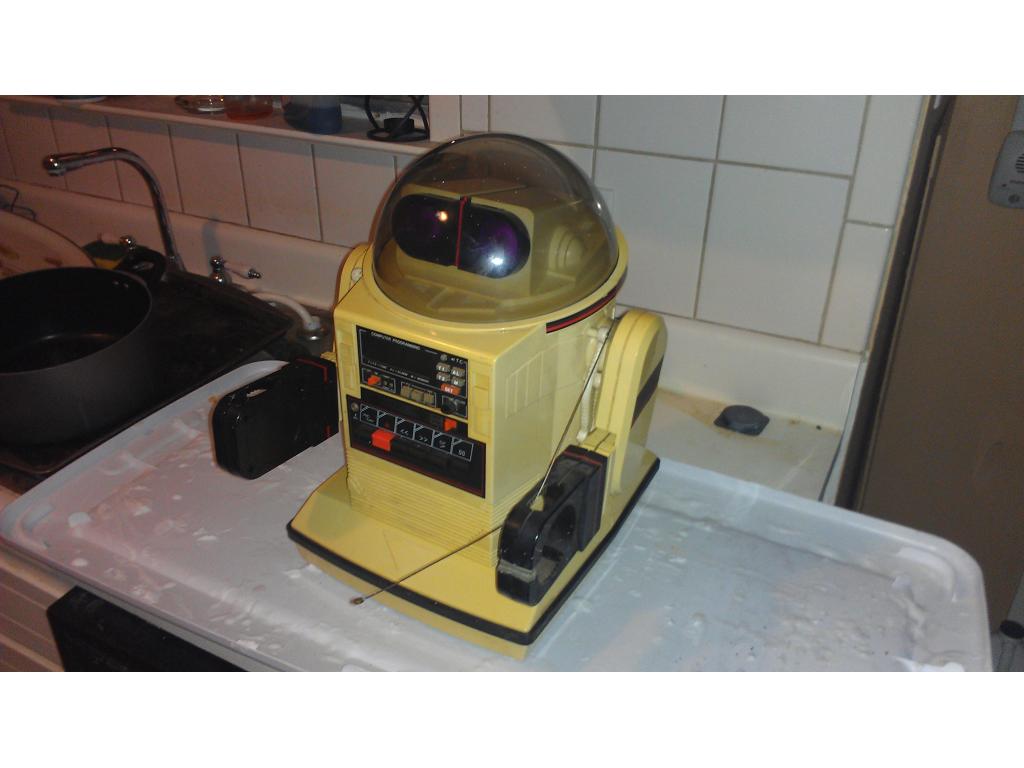
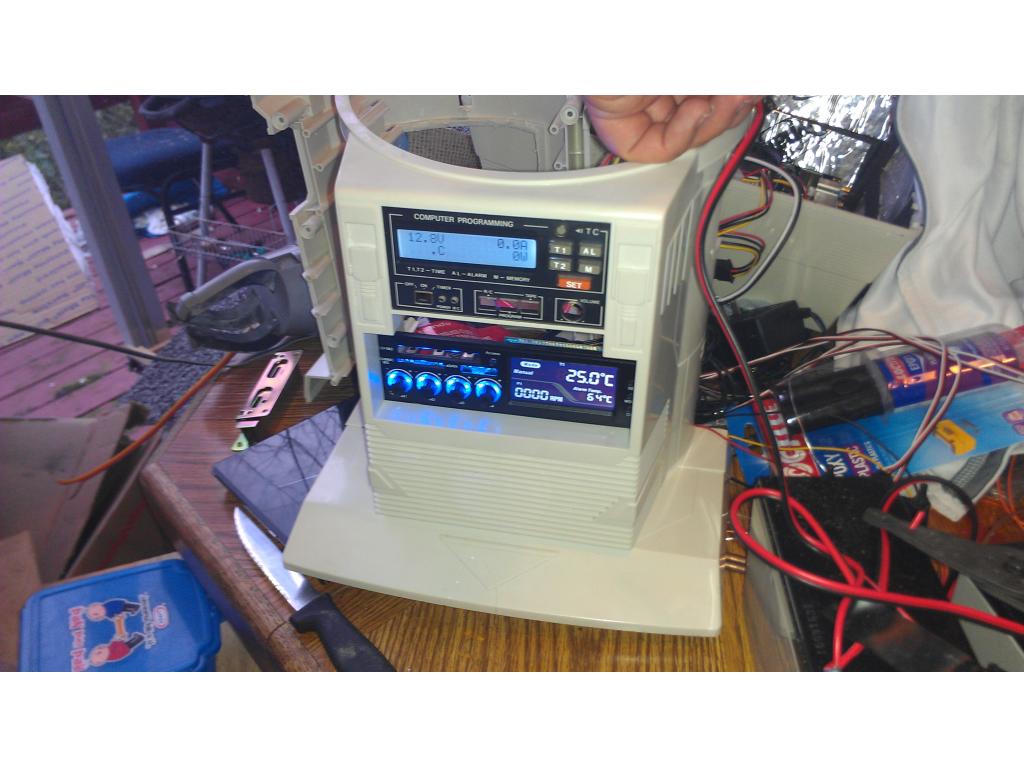
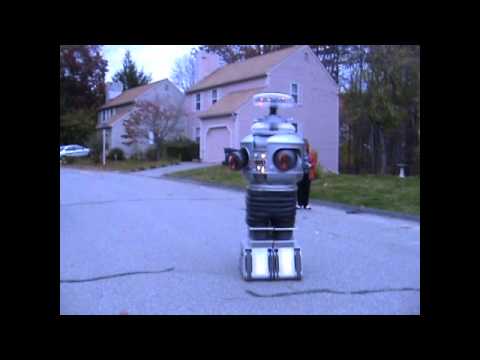

Yea I only have my phone for videos , I would love to see jarvis move too , lol , give me about ten days and I will be able to do basic tests for movement , I have a servo.tester from servo city on the way so I can test movements faster and work on ezb once its back from paint.
@ thankyou Sam ! Mad props she is tackling the difficult curves of the omnibot 2000 base. I'm thinking of taping off a couple strips maybe 3 inches tall and maybe 8 inches long and leave those clear and paint the rest body color. Here's a basic pic without the supports in the corners , she has to bend the front some I believe.
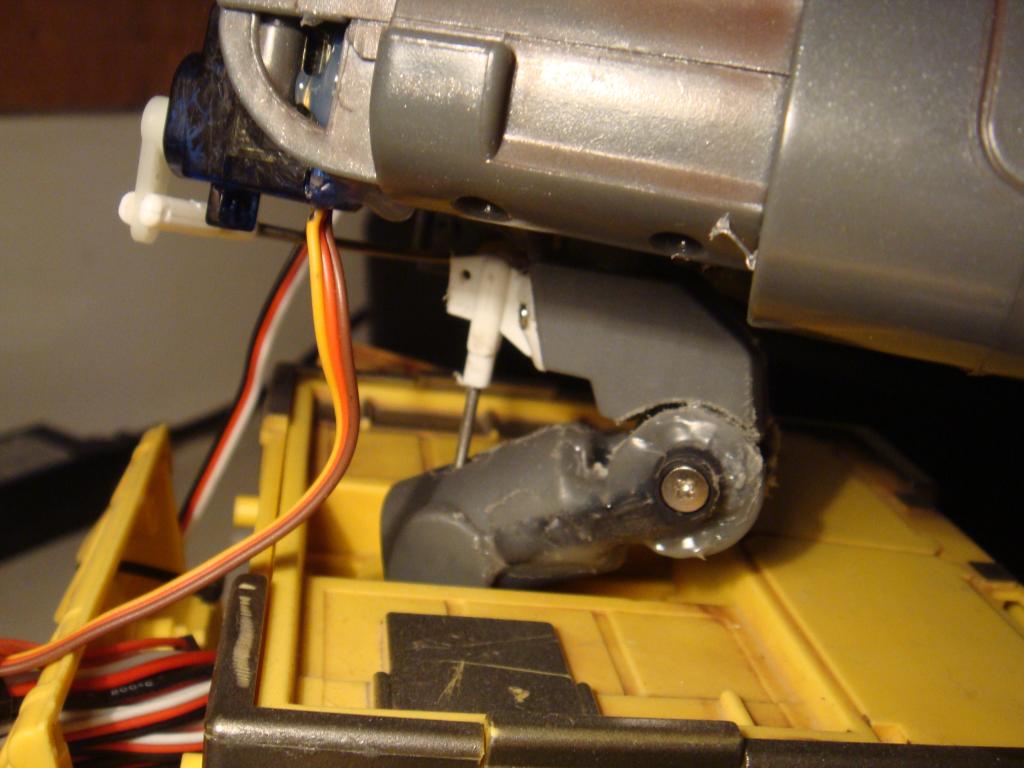
The servo.gearbox does not sit completely flush because of the curved body. I filled the hollow cavity inside the body with high strength epoxy , then on the inside I will follow up with a layer of fiberglass. The nuts for mounting will be glued in place. I can trim away a tiny bit of plastic so it sits flush then , otherwise I'm super excited.
your phone is lucky it can take video's, mine cant stress stress but still video's are not needed only self testing to prove a design works or doesnt work as good
Nice! Man I am getting excited to see him move too! Can't wait, can't wait, can't wait... Oh, your duct went out yesterday. You should have it for the weekend. Let me know if you need any more.
yea when will he be fighting crime soon
also did you see JOSH they have at servo city a 4000 oz servo ,no gear box is needed ,i think they are $529 each mega servo ,might be a good idea when i make a bigger omnibot
any new updates,photos or video's on the jarvis yet JOSH


Nopers , I'm still at work , I think sams not off work yet either so no updates lol. I won't do much tonight , maybe just start molding in the vacuum I believe.
can you post a photo of the bottom of your robot,i thought you cut the plastic away for some tracks you made in a early post of your omnibot project,
No I never cut anything out for tracks.