

Hi, everyone!
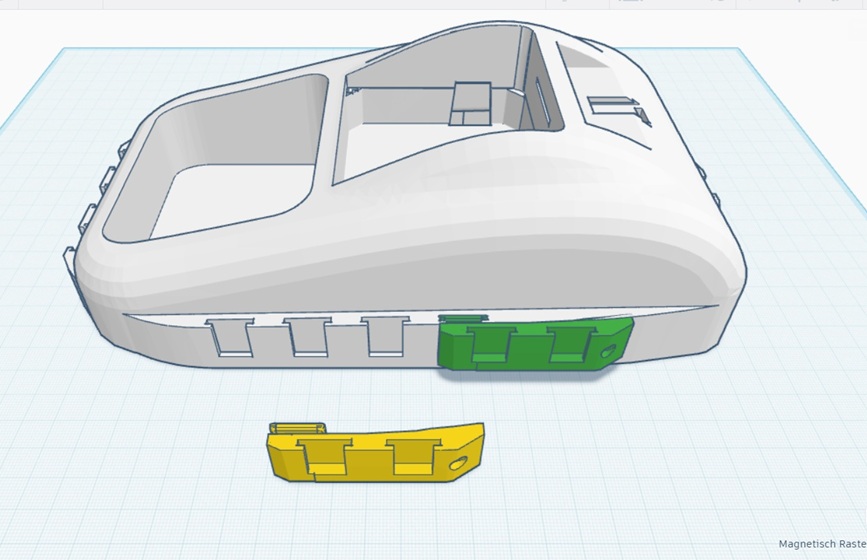
I have created a component called "rolliclip" that allows you to adjust the robot arm forward by 1.5 holes.
Here’s an image of the rolliclip:
You can download the STL files for 3D printing here:
- rollisupportR.stl - rollisupportL.stl Let me know if you have any questions or feedback!

hi
here's how it looks .
short video
https://www.youtube.com/shorts/2vijOlRNjLk
Nice work, Nomad. Did you make this so the arms stick out further?
hi dj
yes . you can use one servo less from the arm and still have longer reach . this way the last servo doesn have to carry the load of a full arm .
thank you
This will be very useful. Great idea.
Thanks
hello roboteers
what about a support bracket for the rolli arm servo.
this is what i mean .
https://www.youtube.com/shorts/uRvMOd6PPy4
rollisupportR.stl
rollisupportL.stl
hello roboteers
the rolli has arrived and now i can test the support bracket . also testin tail lights for rolli
https://www.youtube.com/shorts/Tyde0T-865I