cE9s4PsOgeBQIORwjd5!~~60_1-634818020230156250.jpg)
Lupuc4g~~60_35-634706297915000000.jpg)
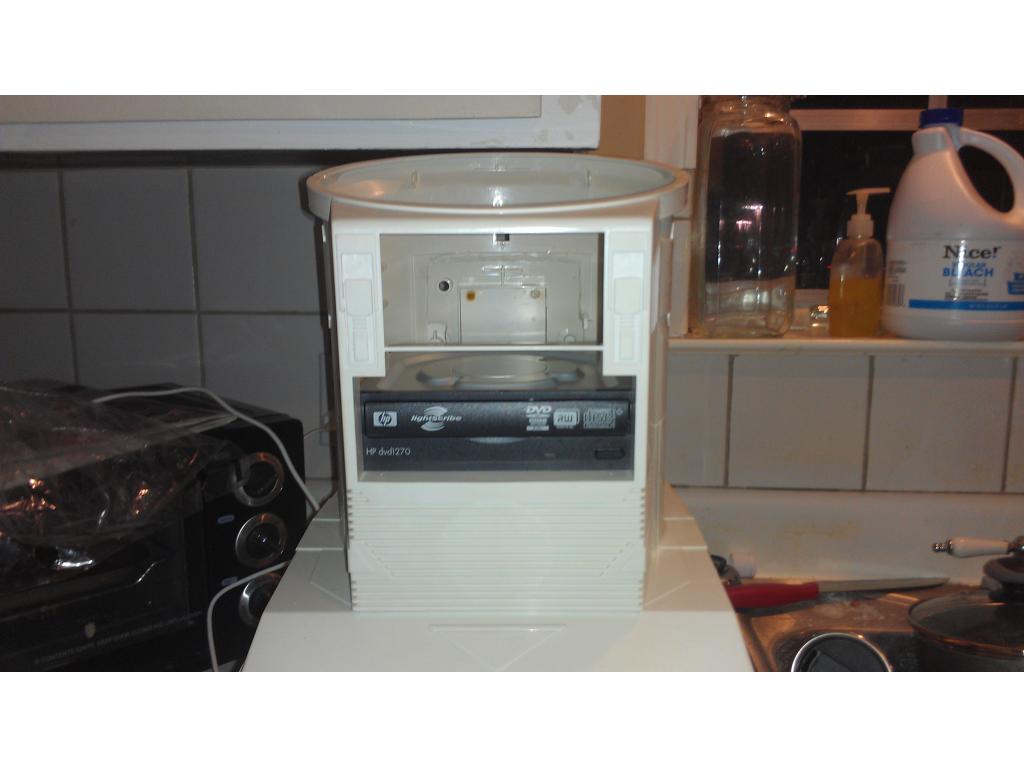
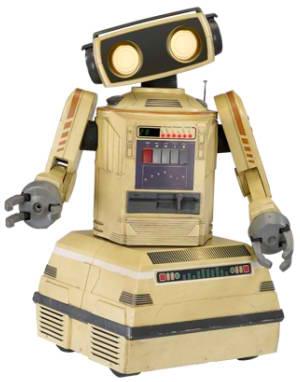
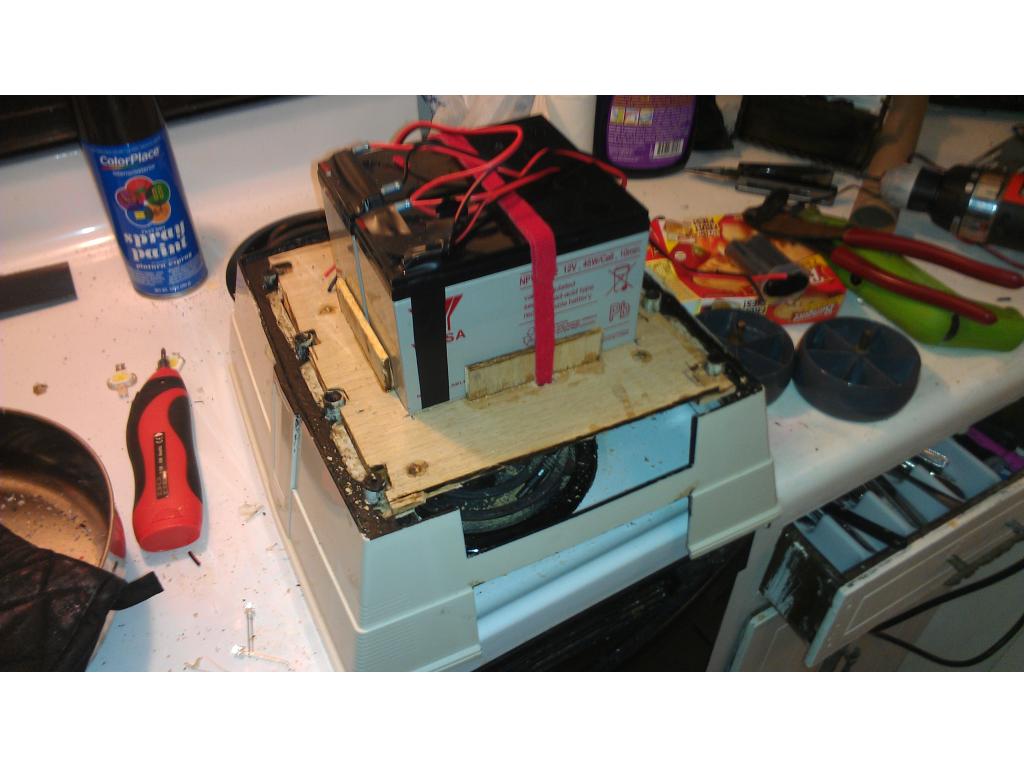
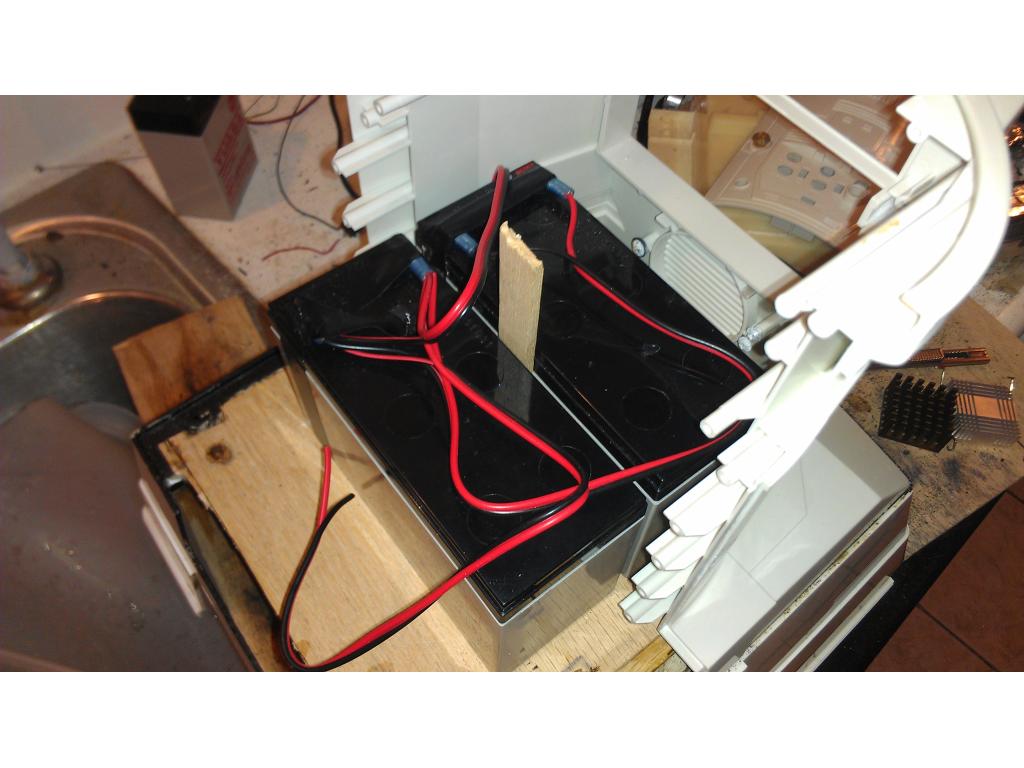
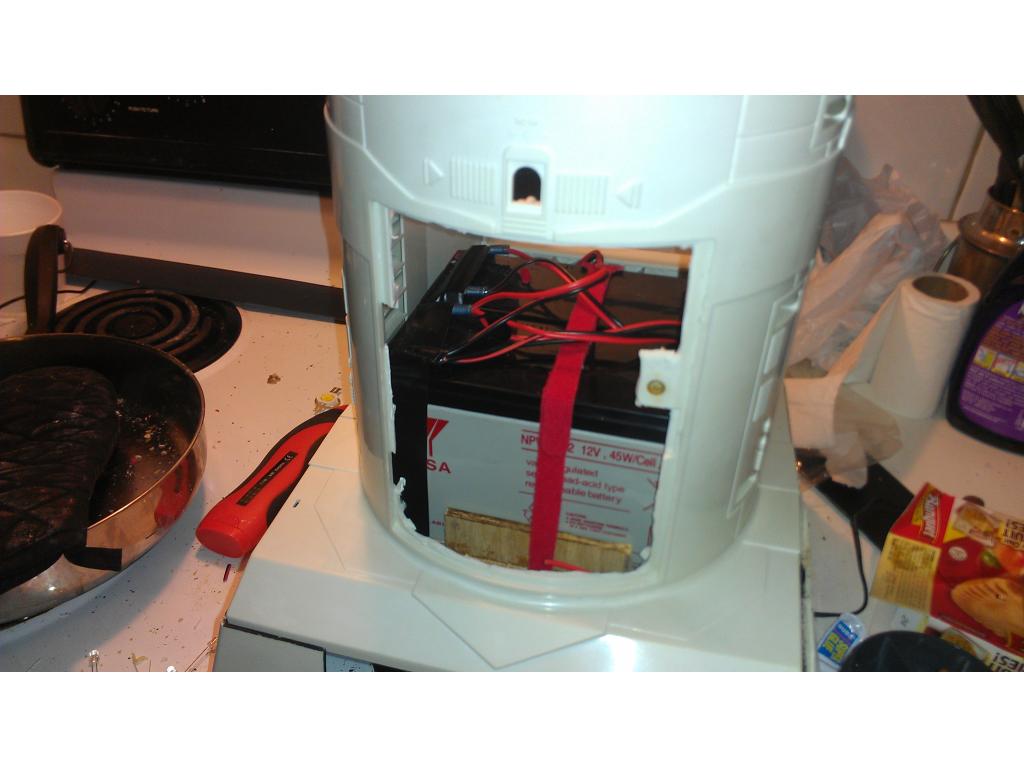
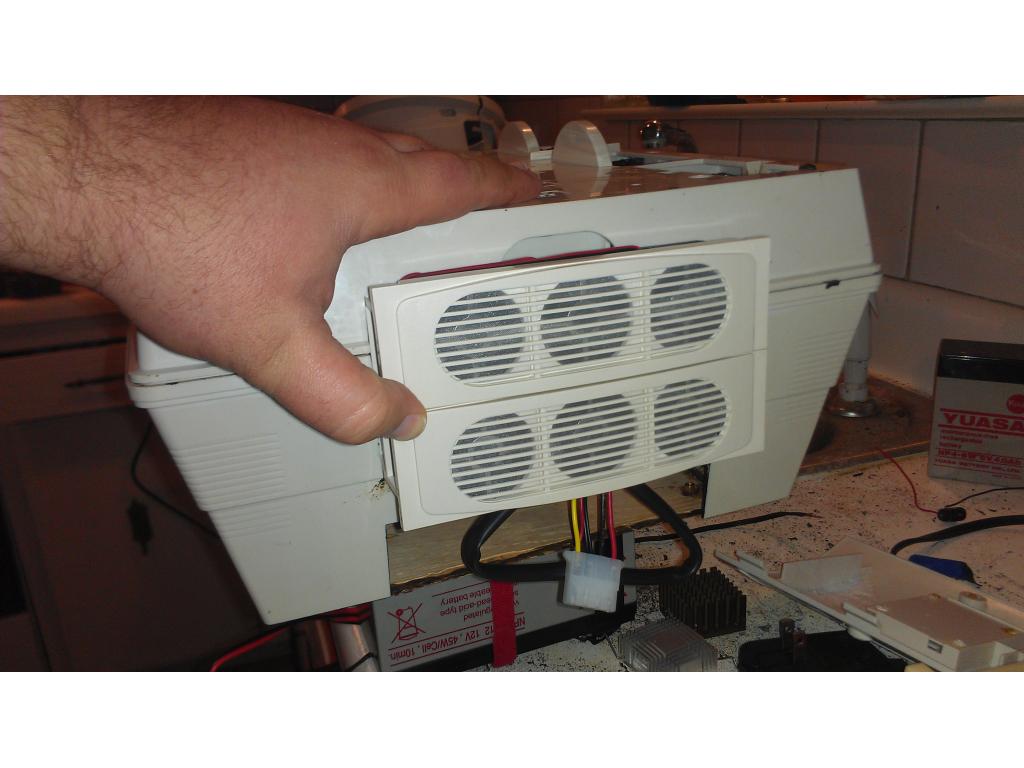
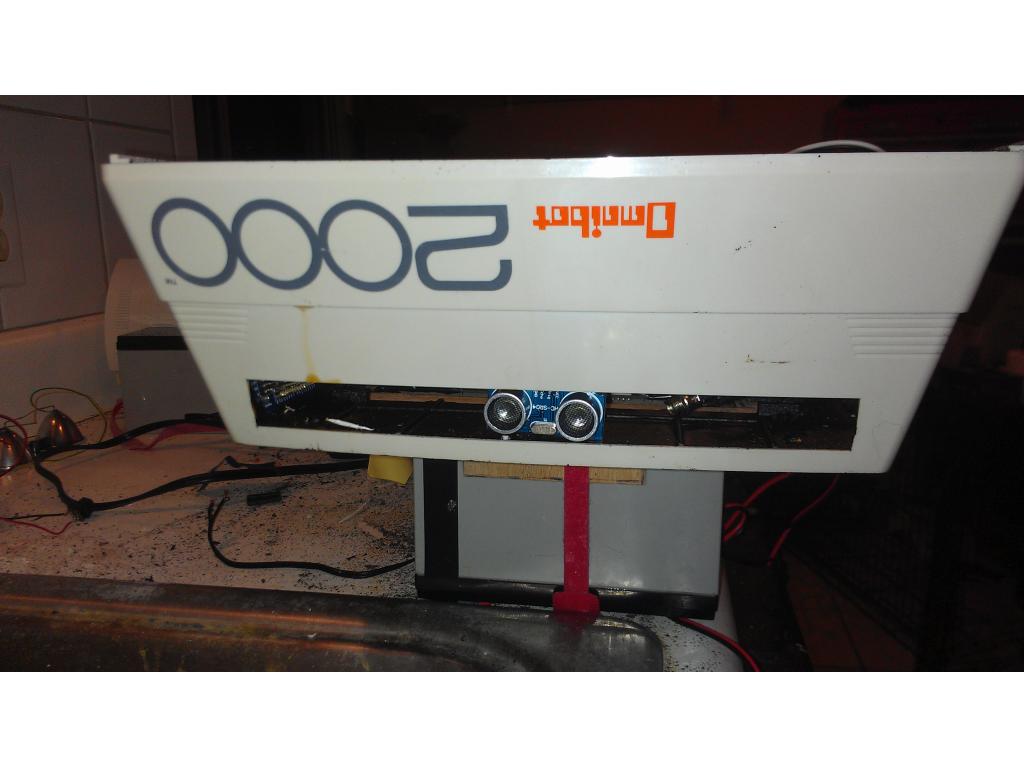
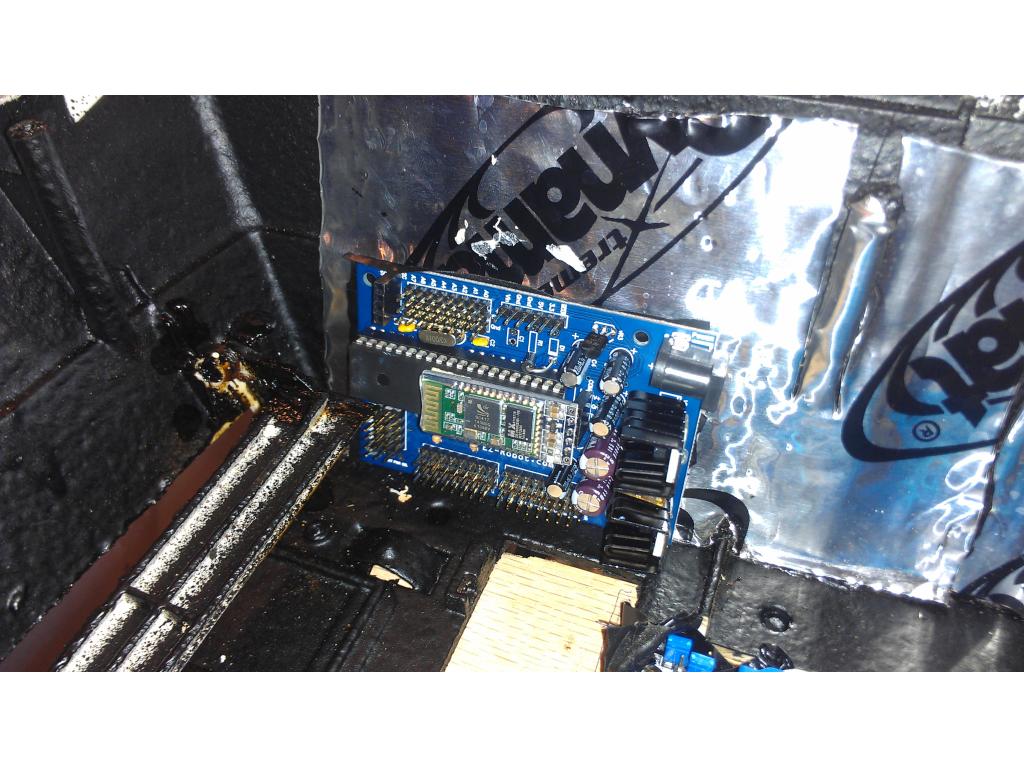
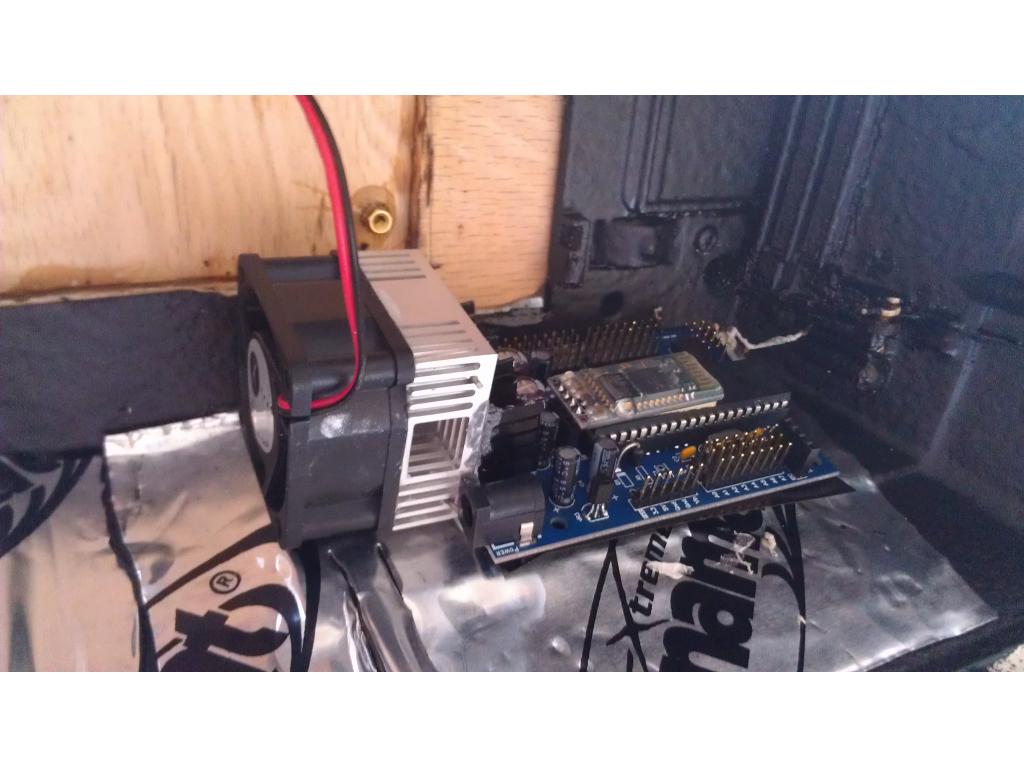
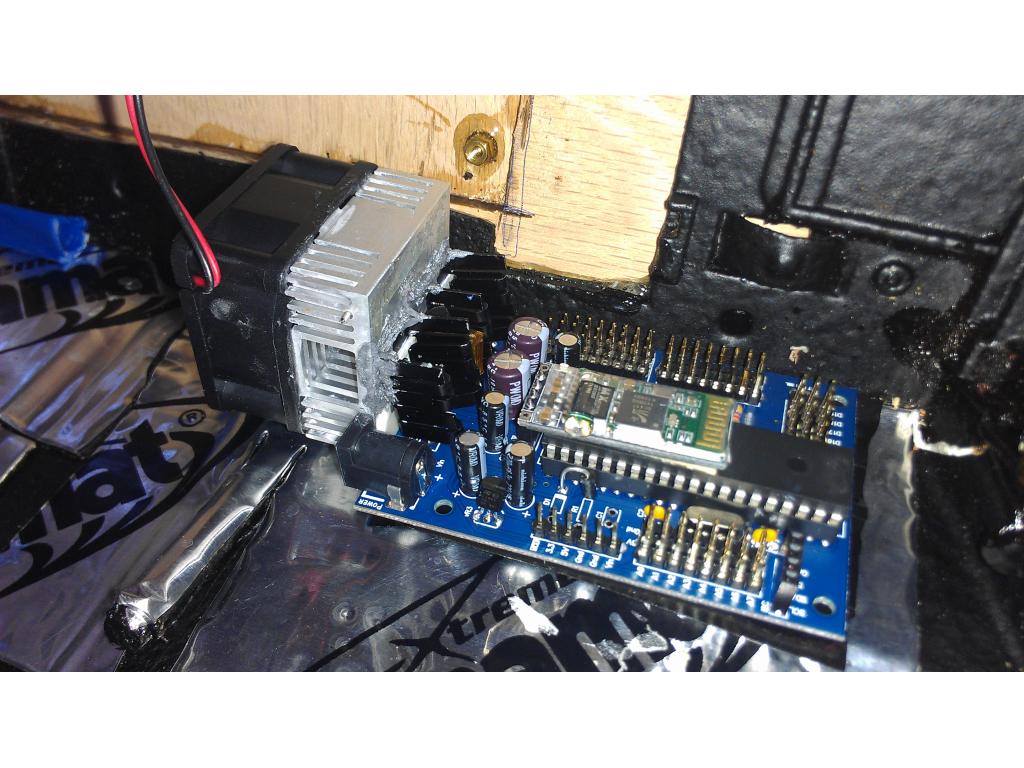
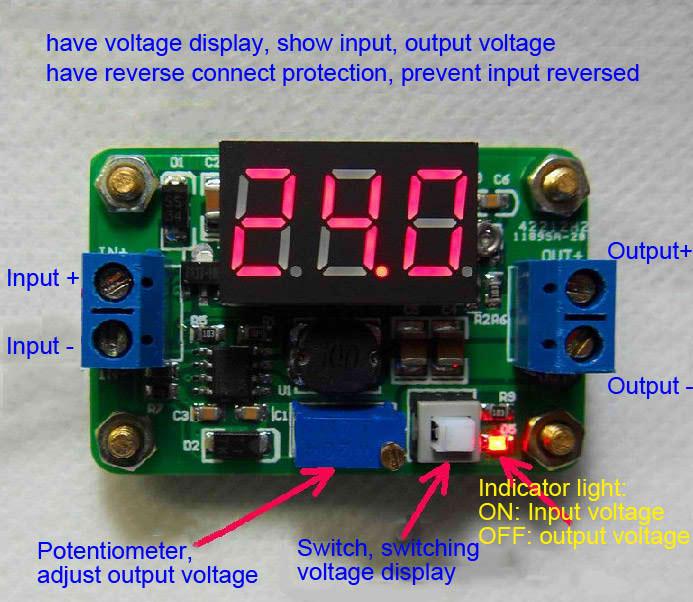
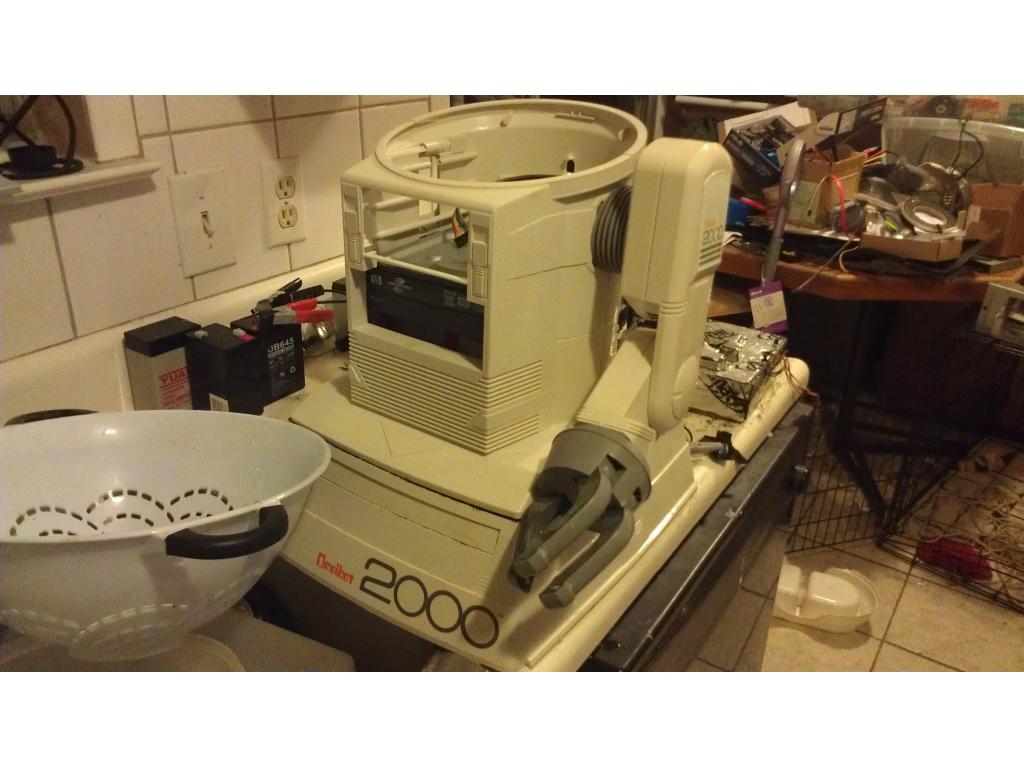
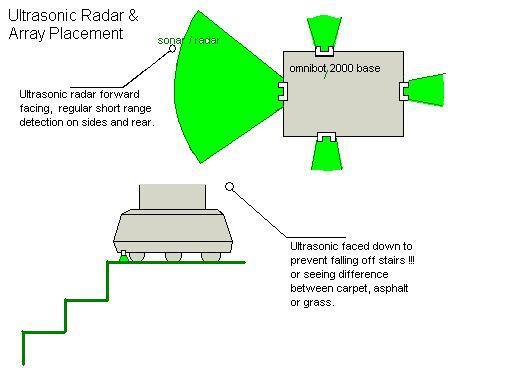
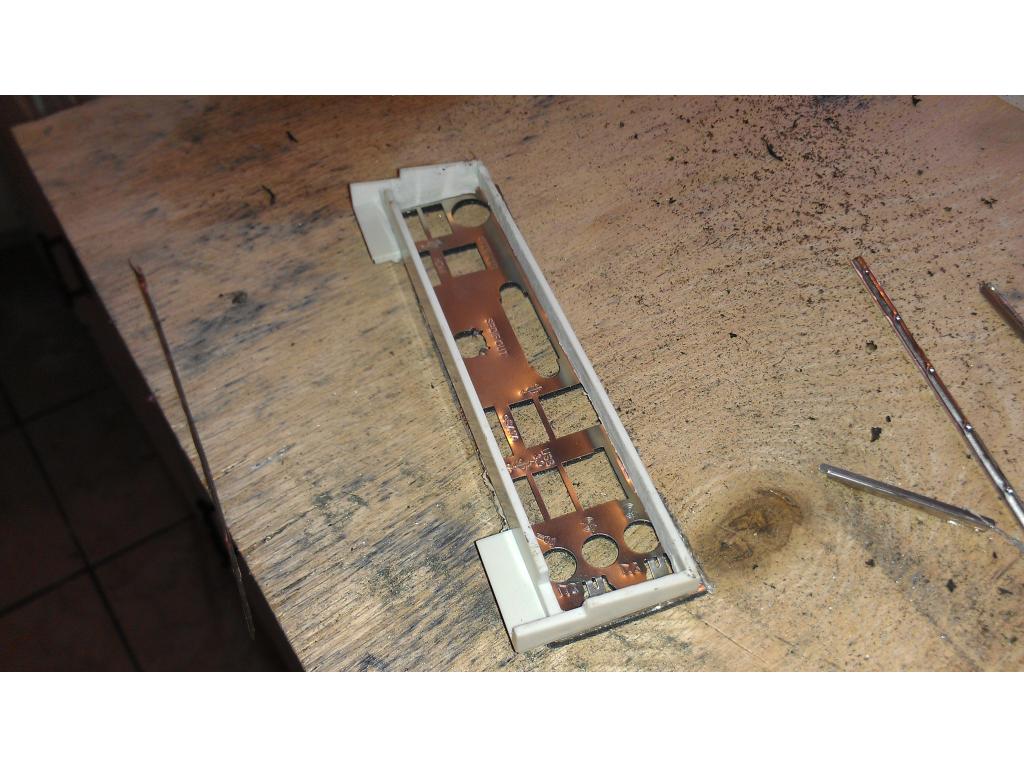
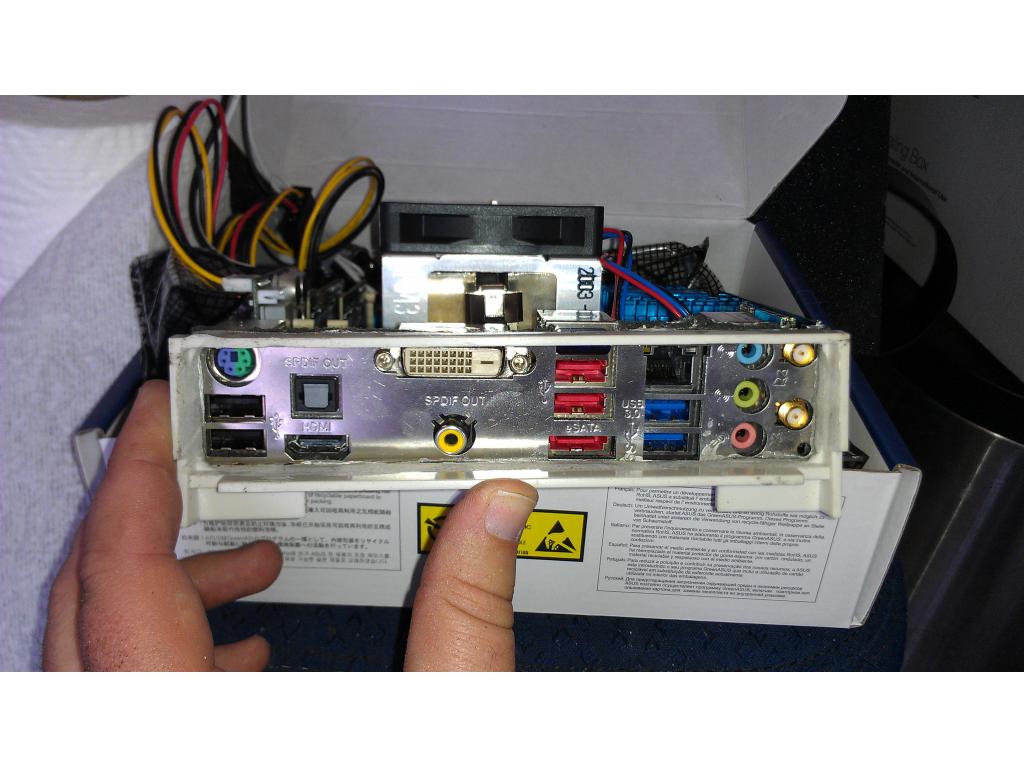
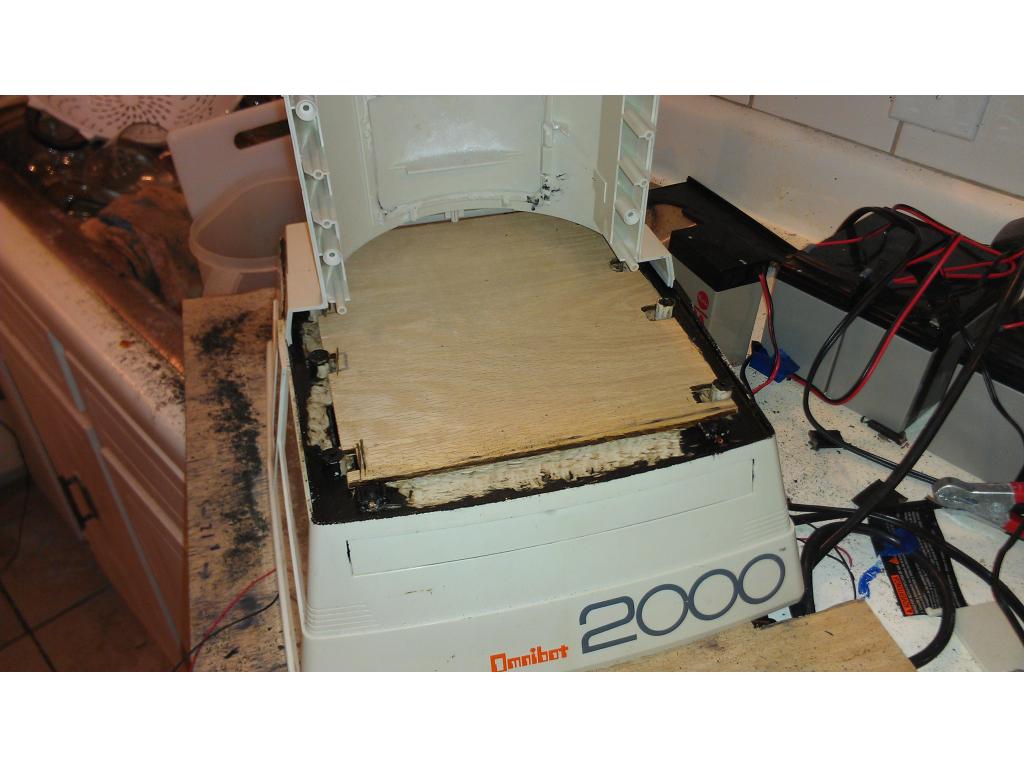
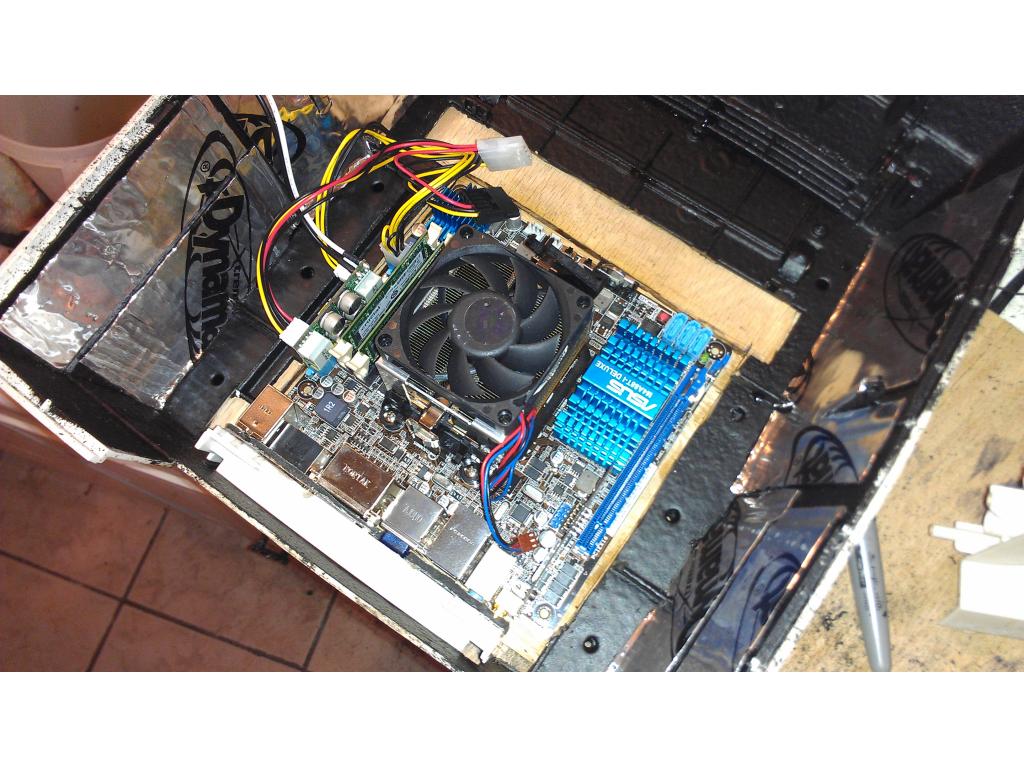
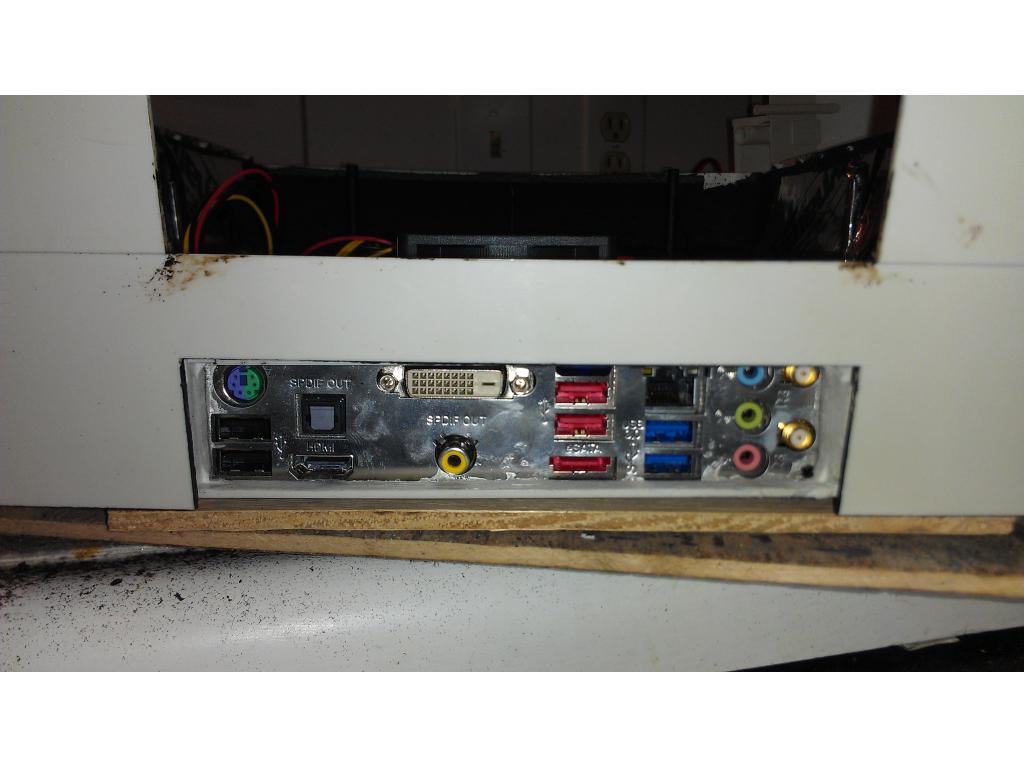
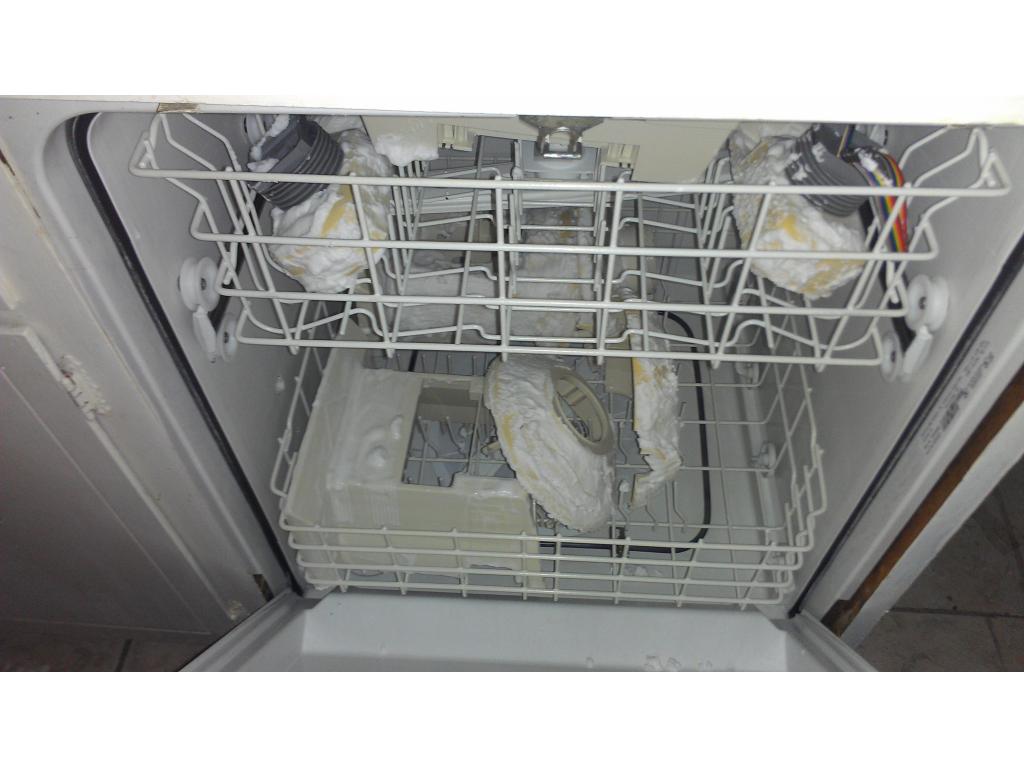
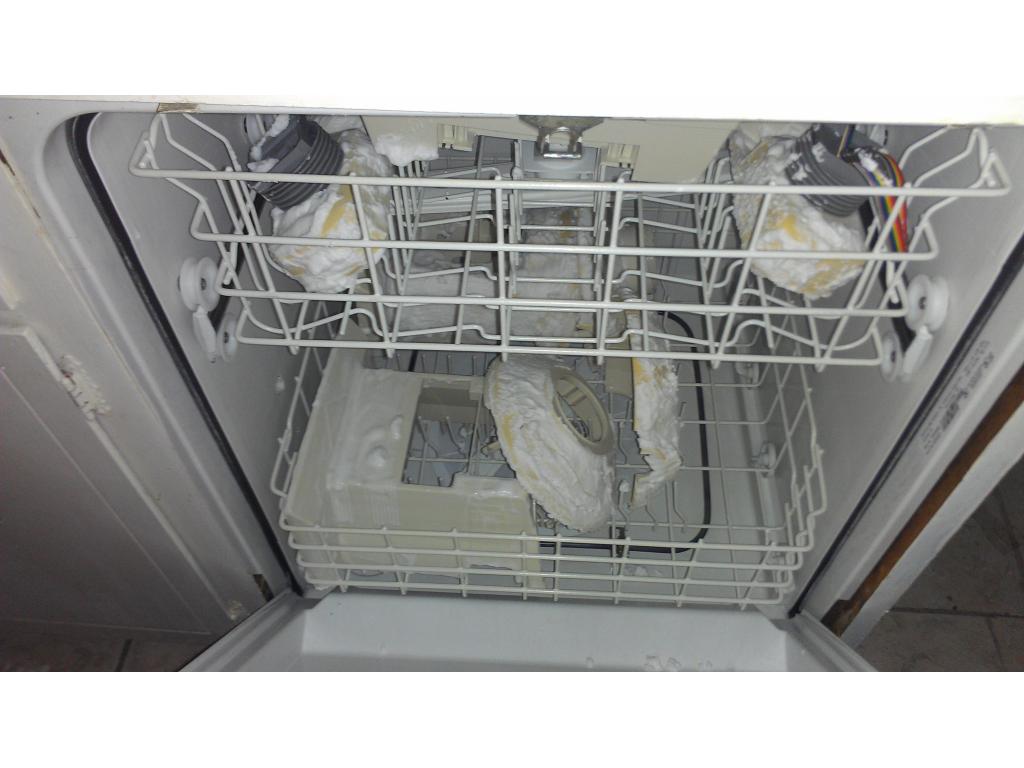
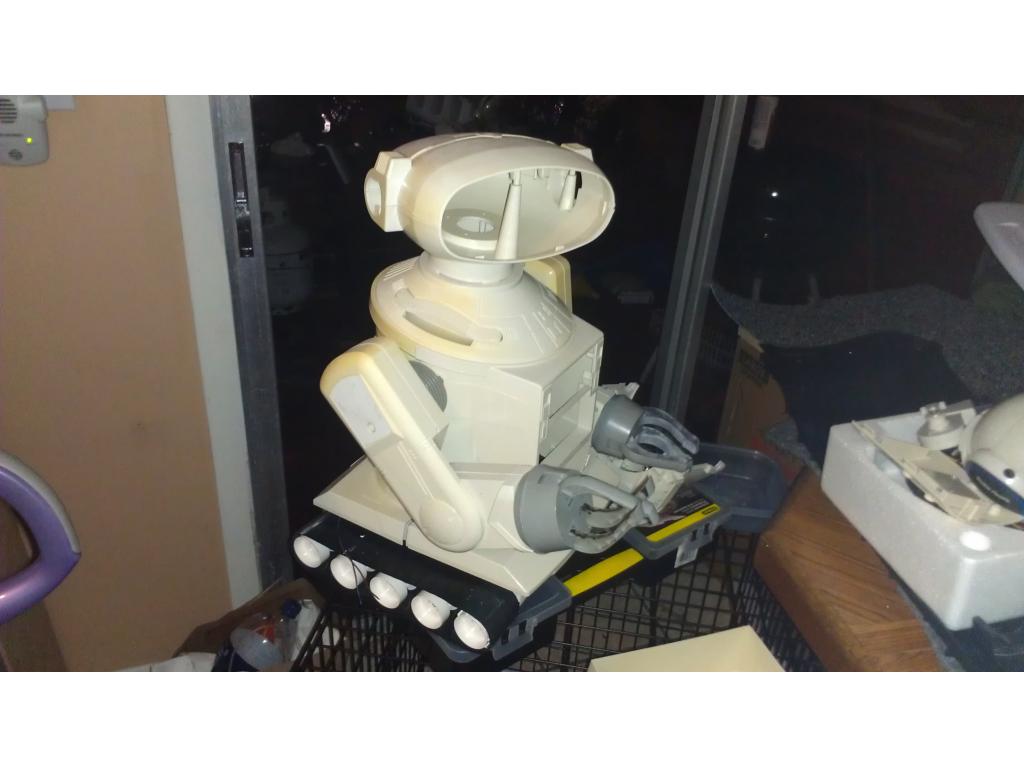
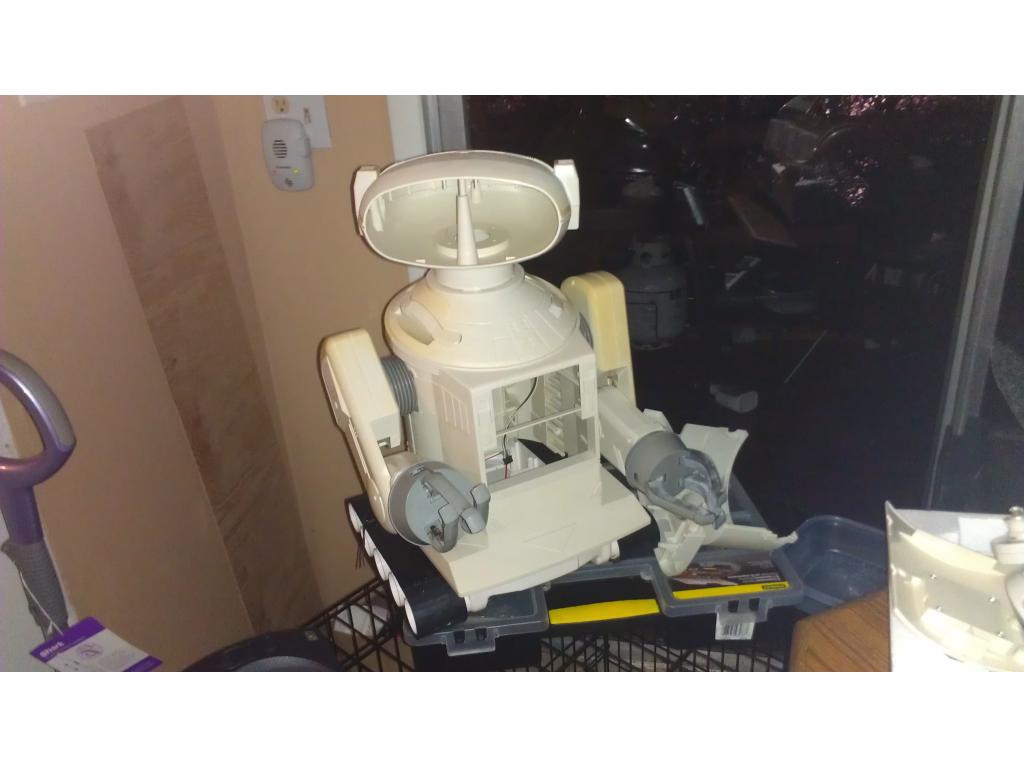
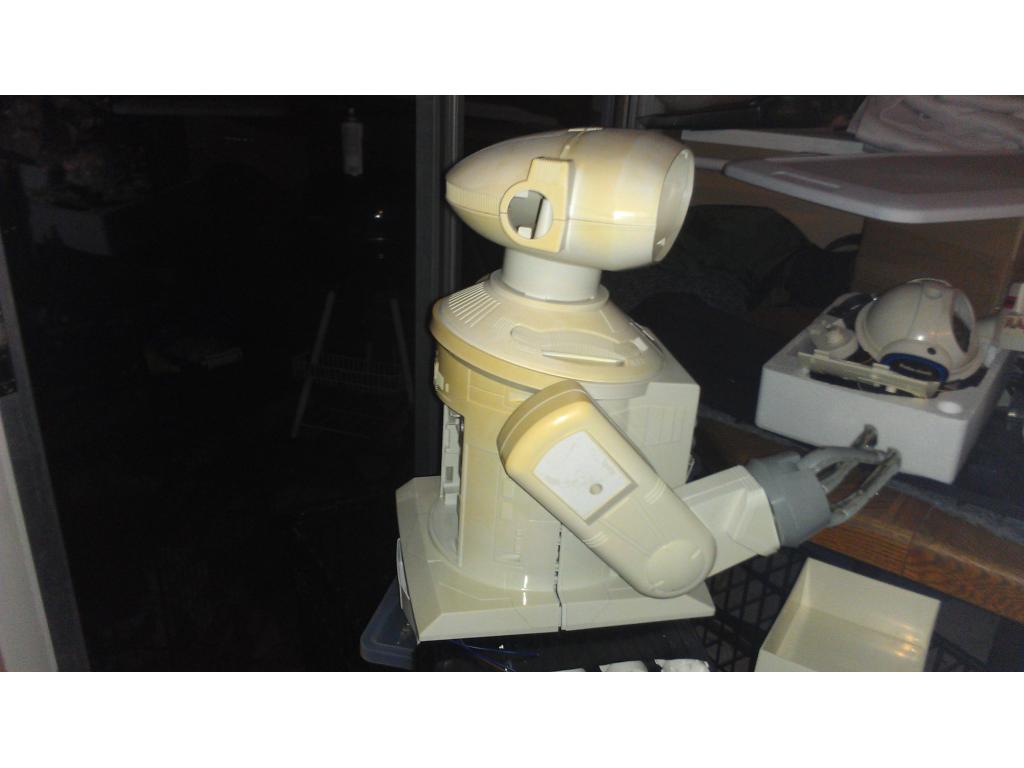
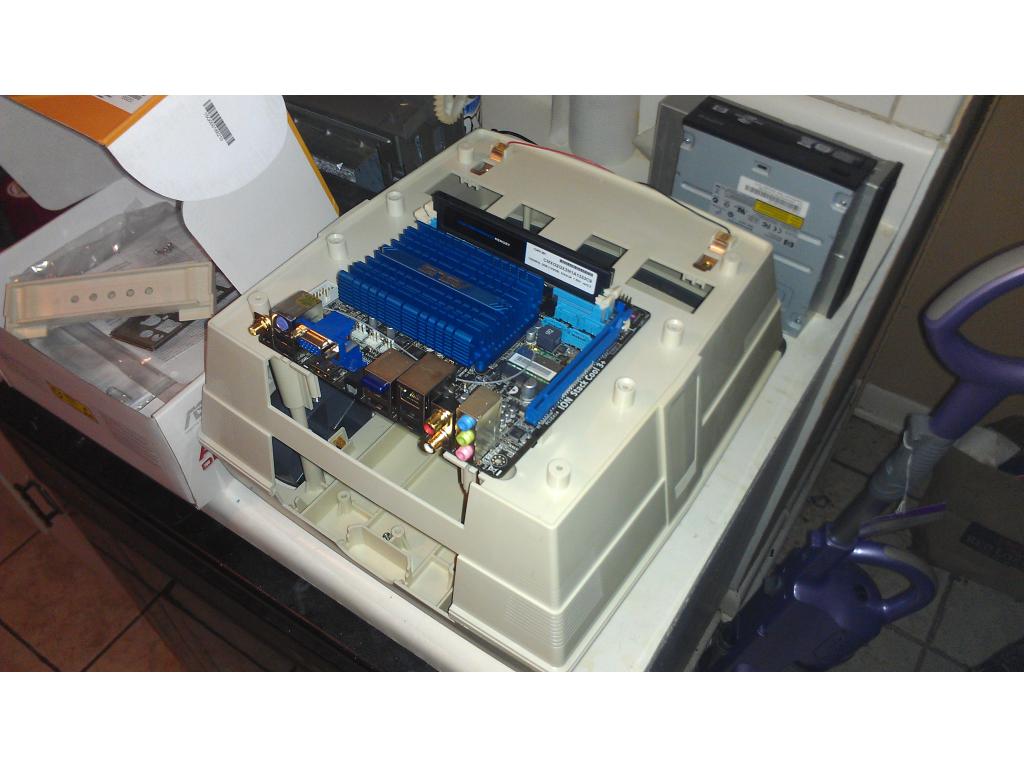
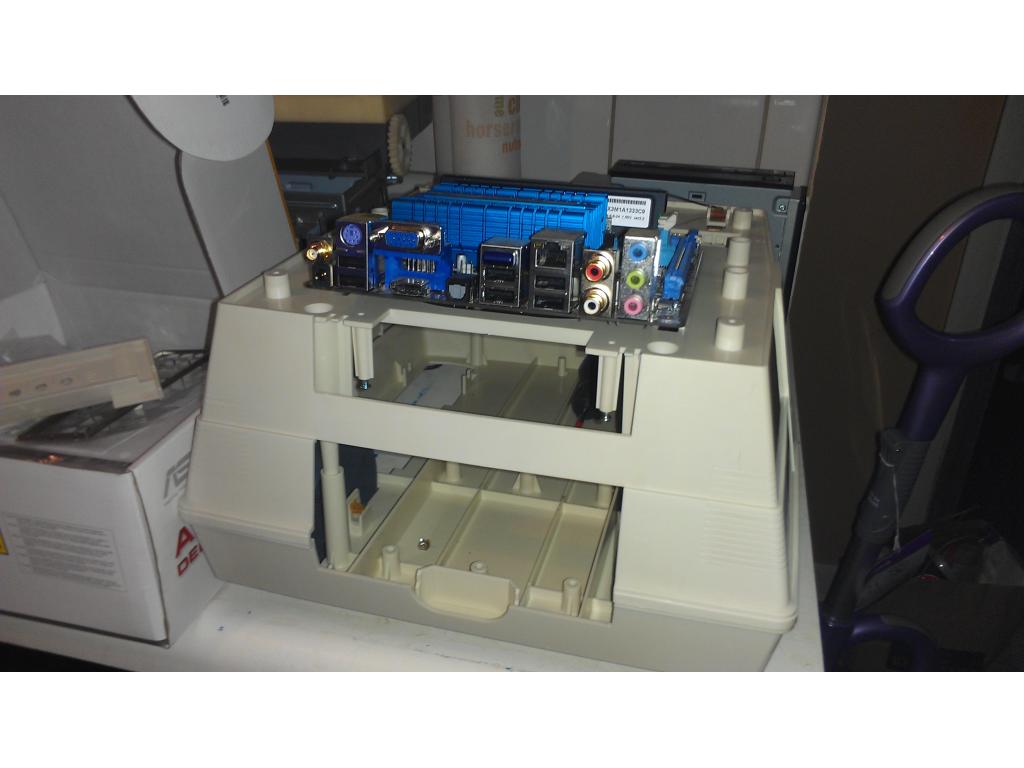
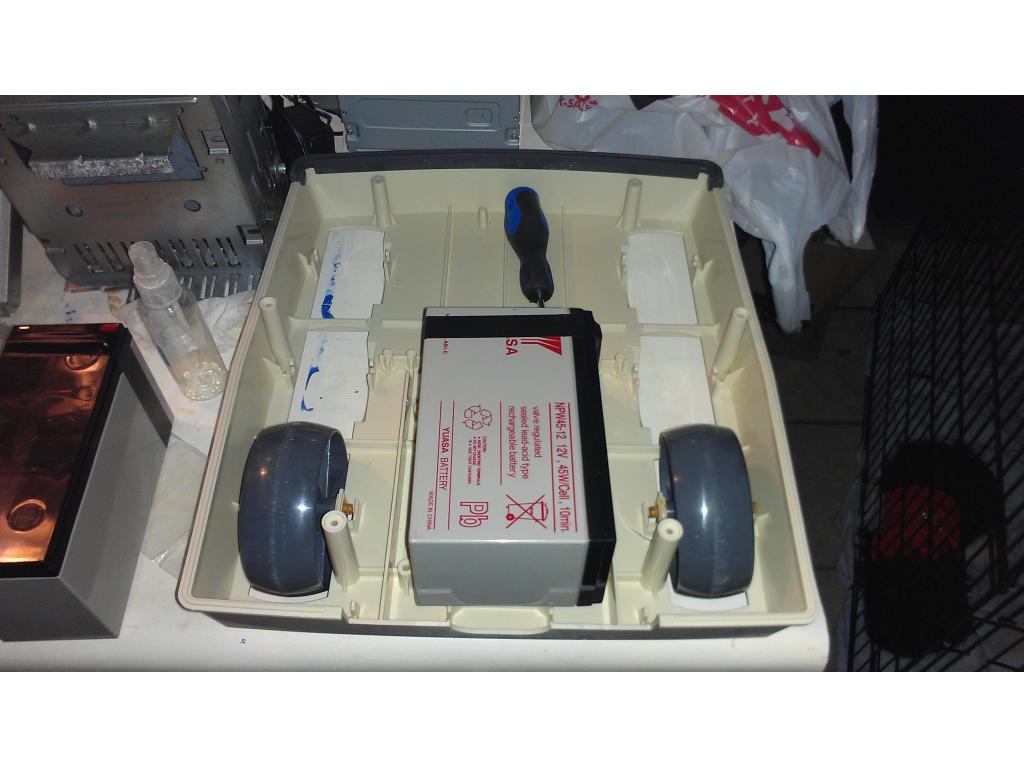
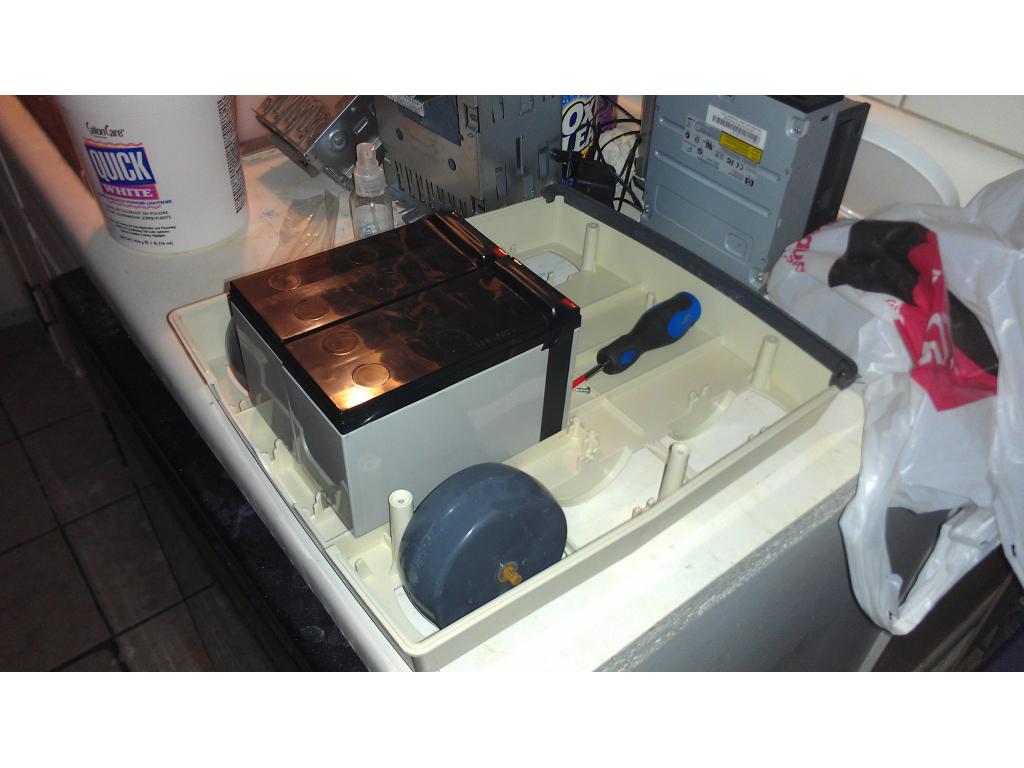
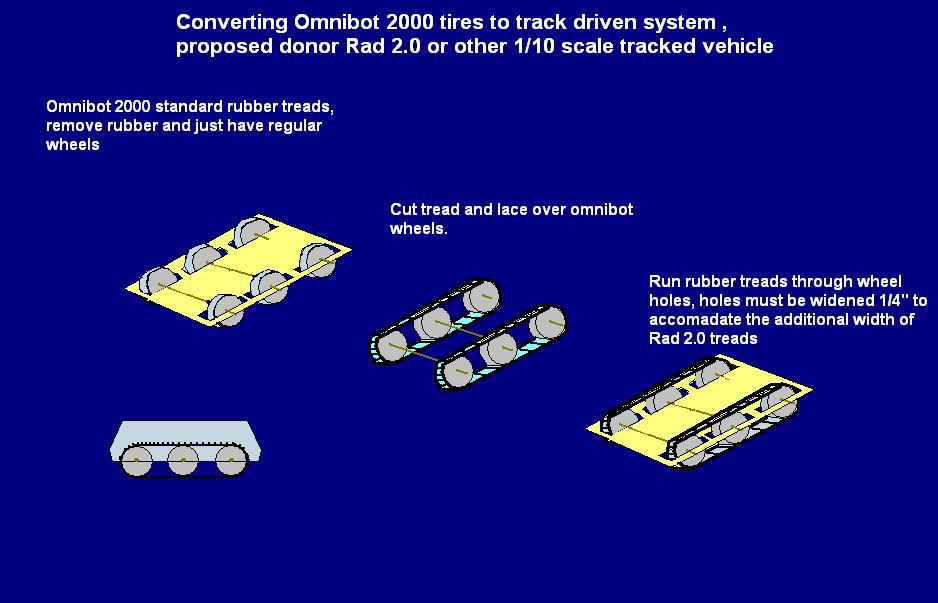


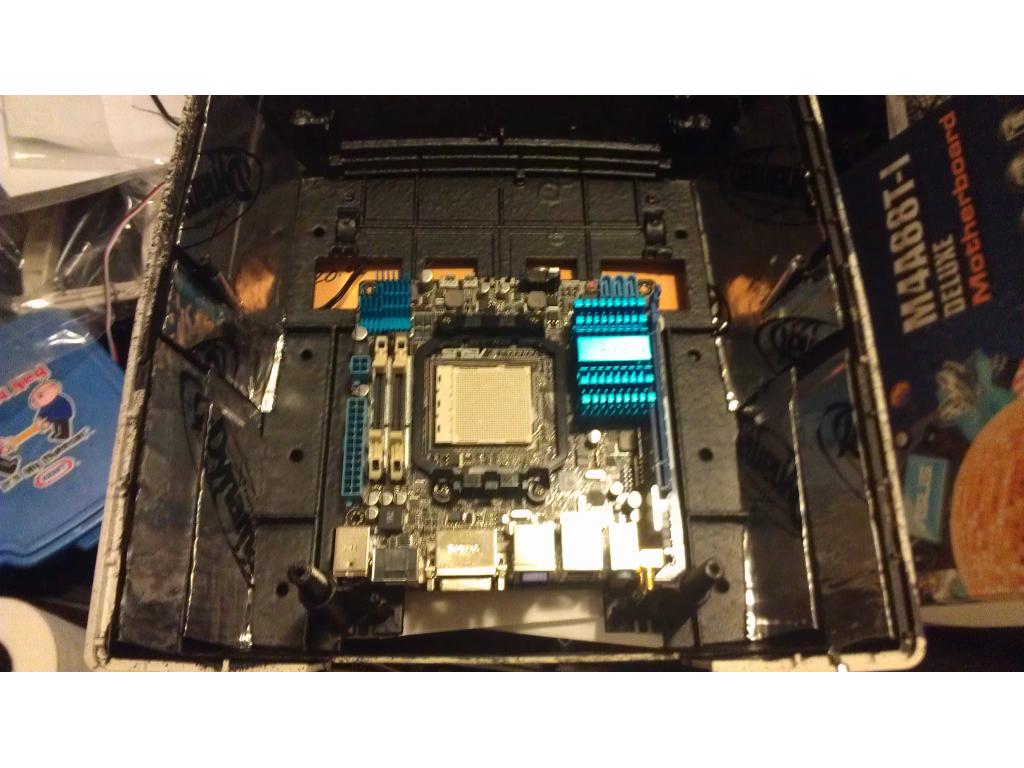
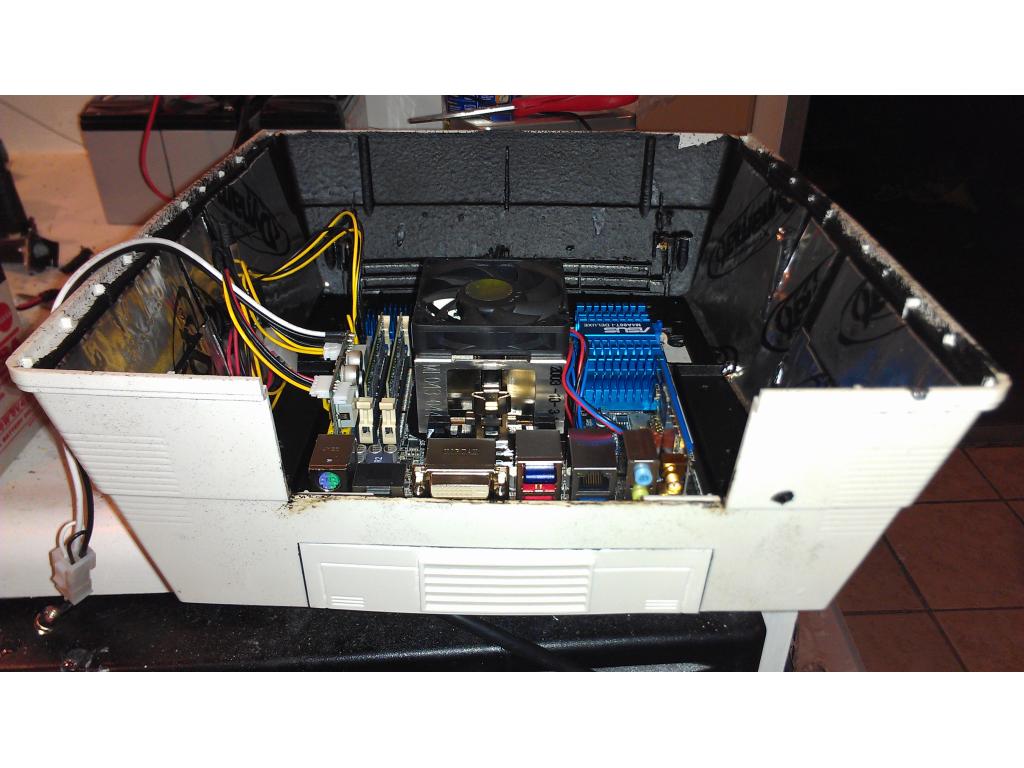
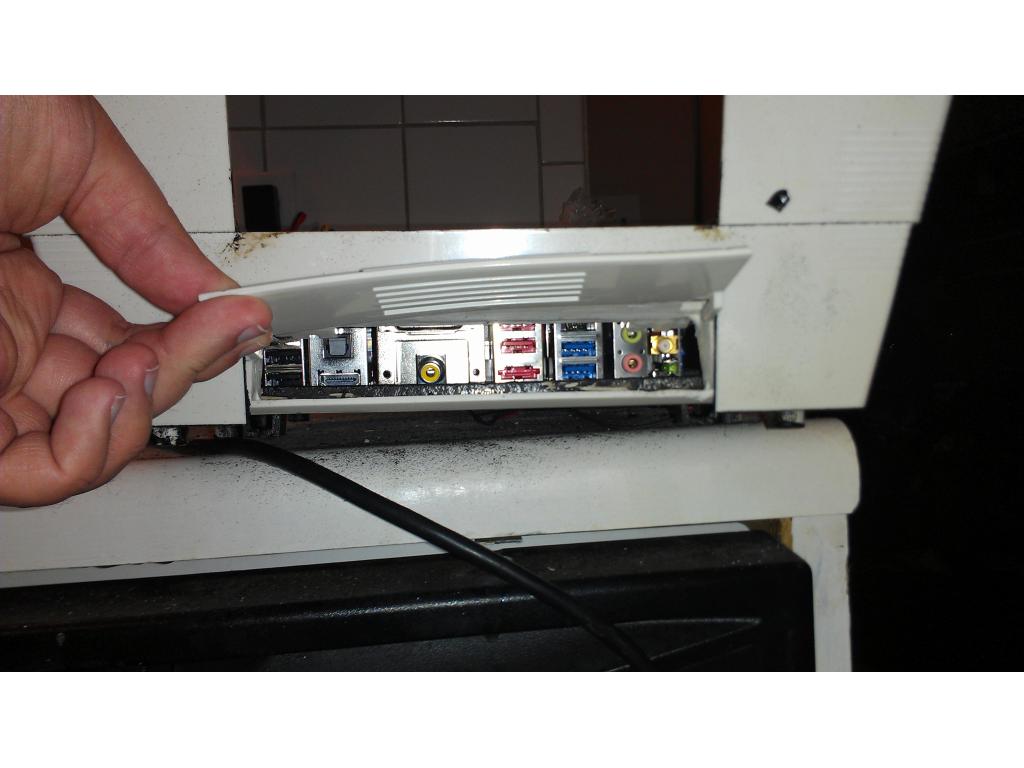
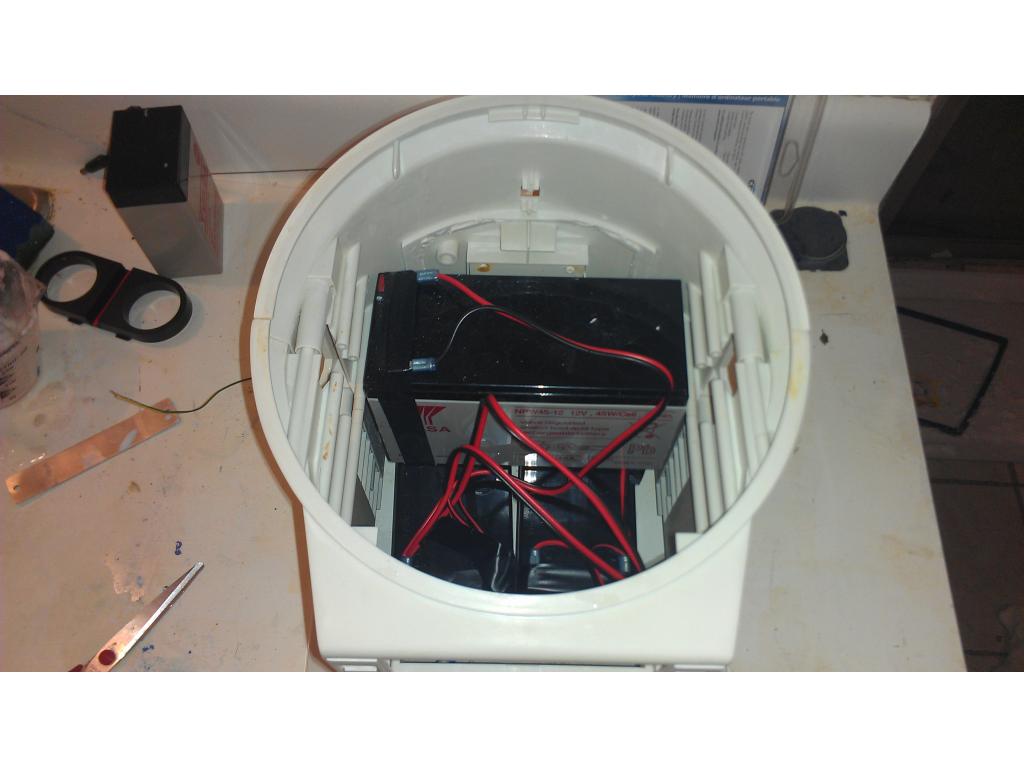
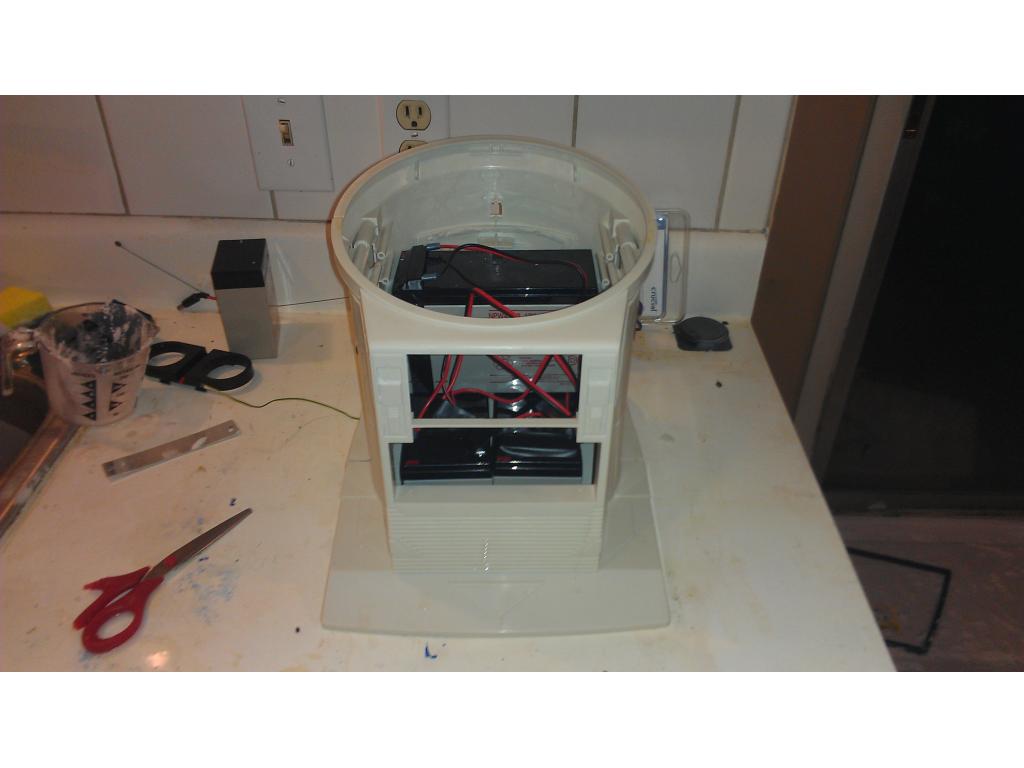
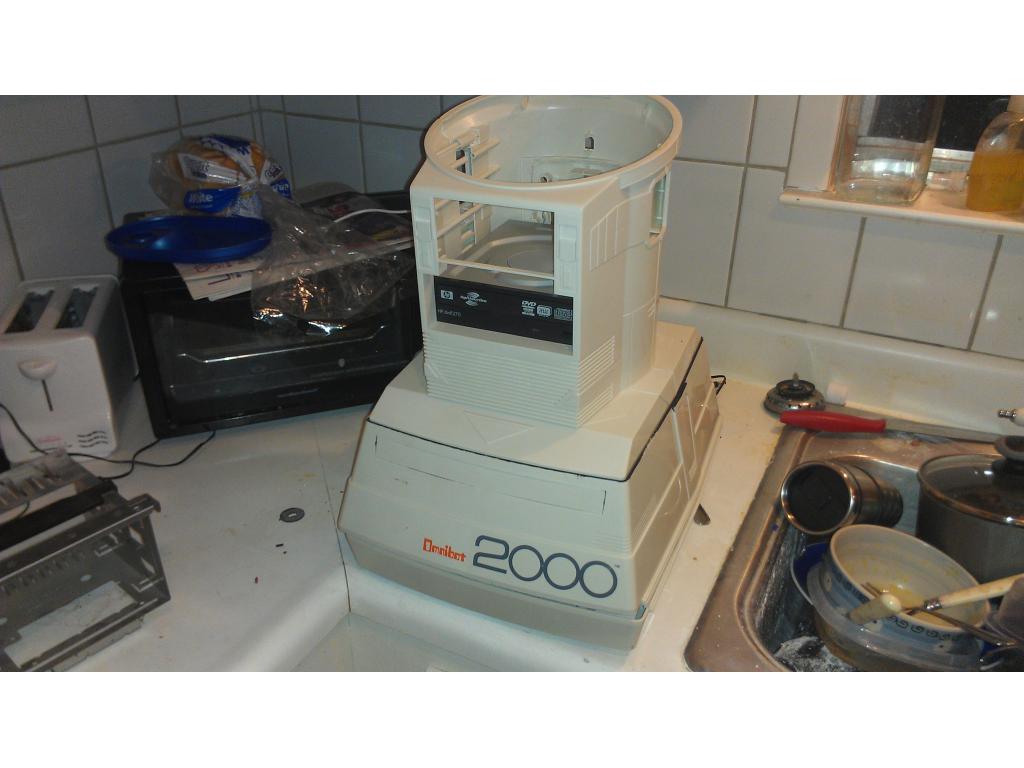
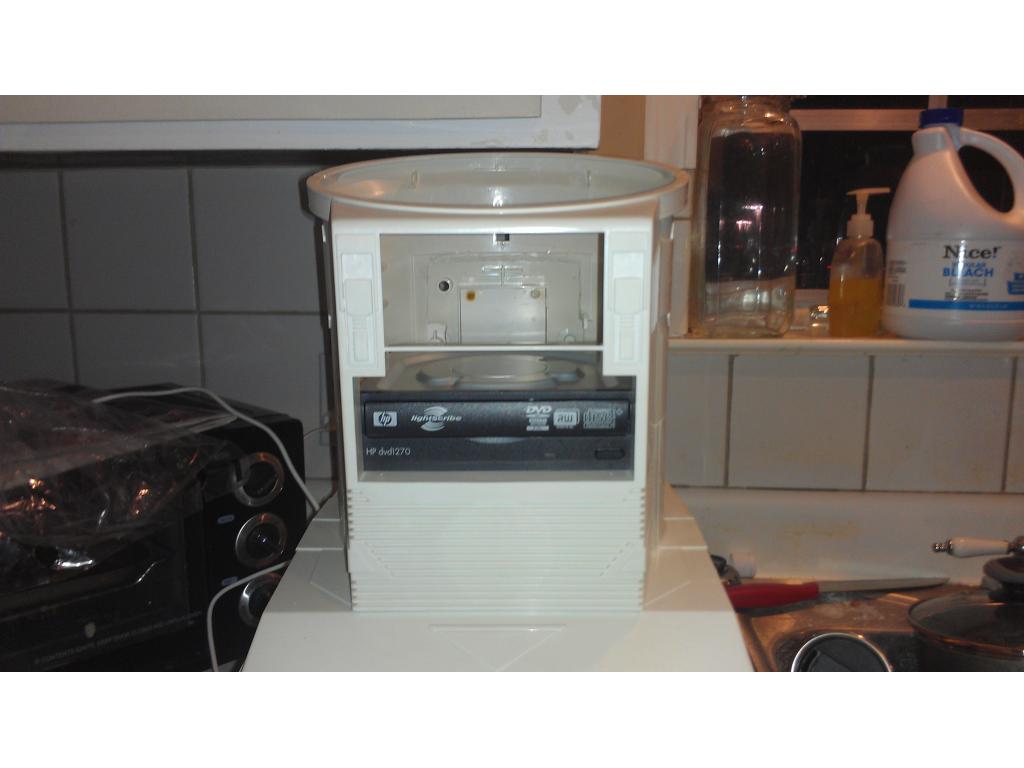
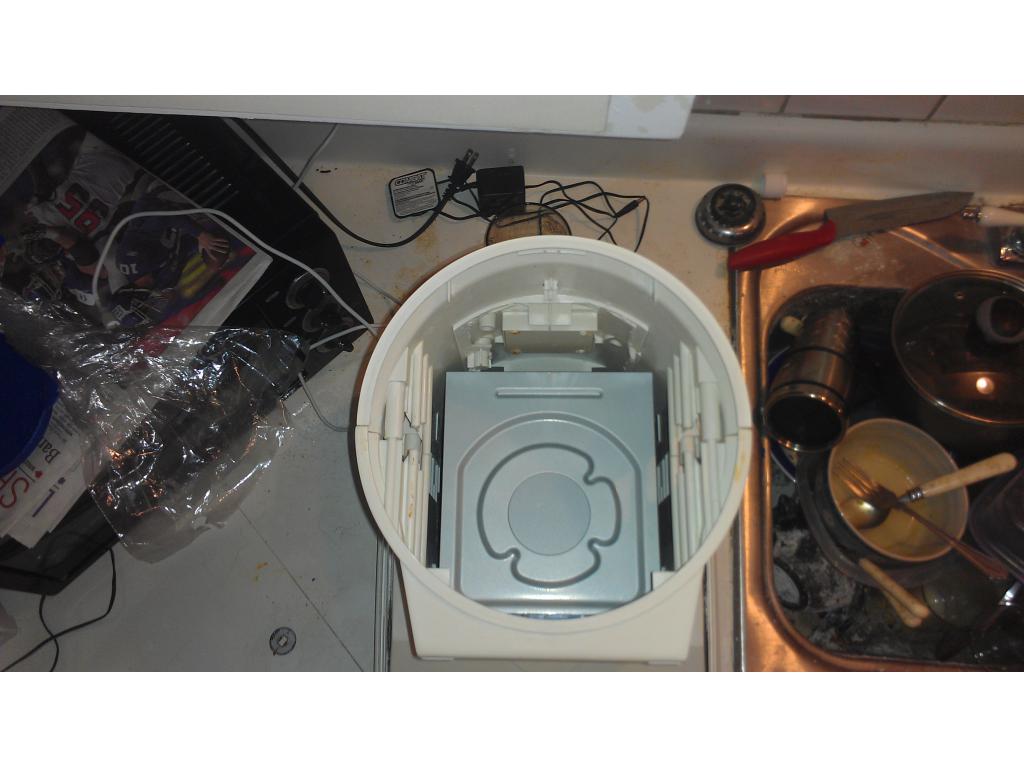
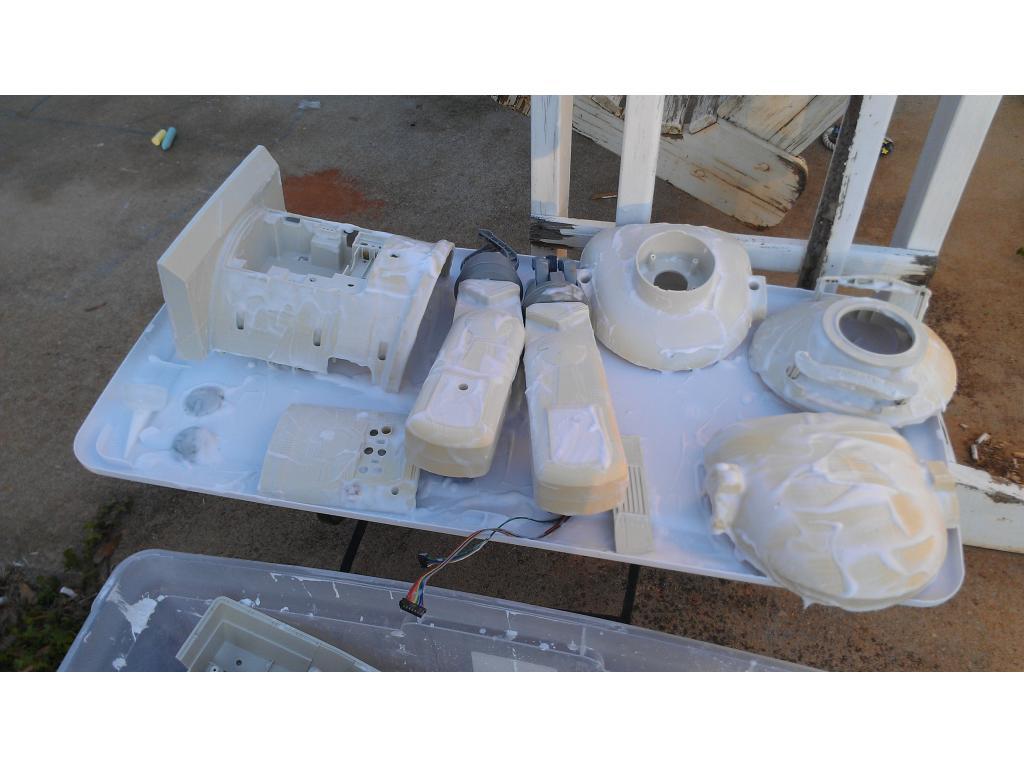
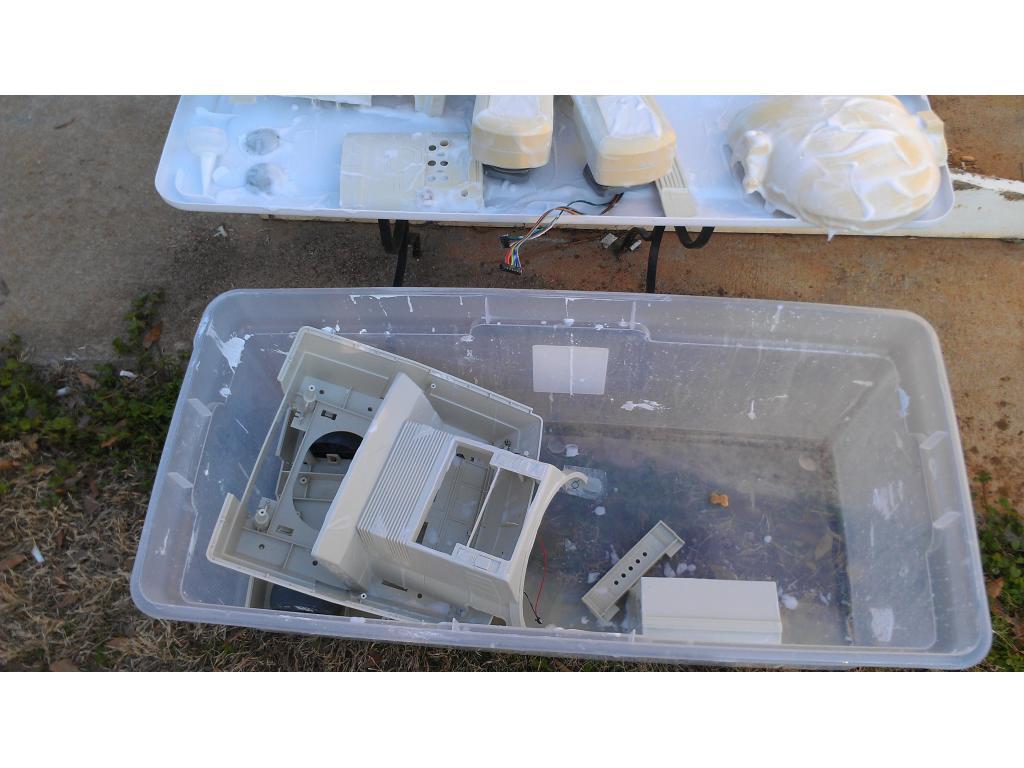
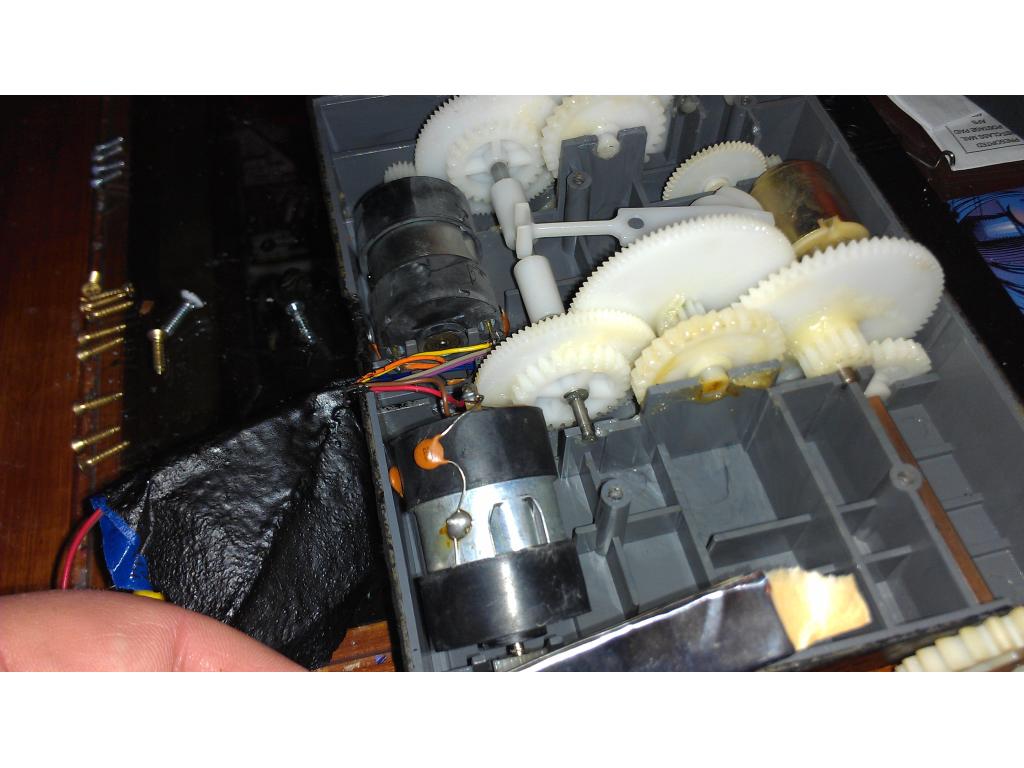
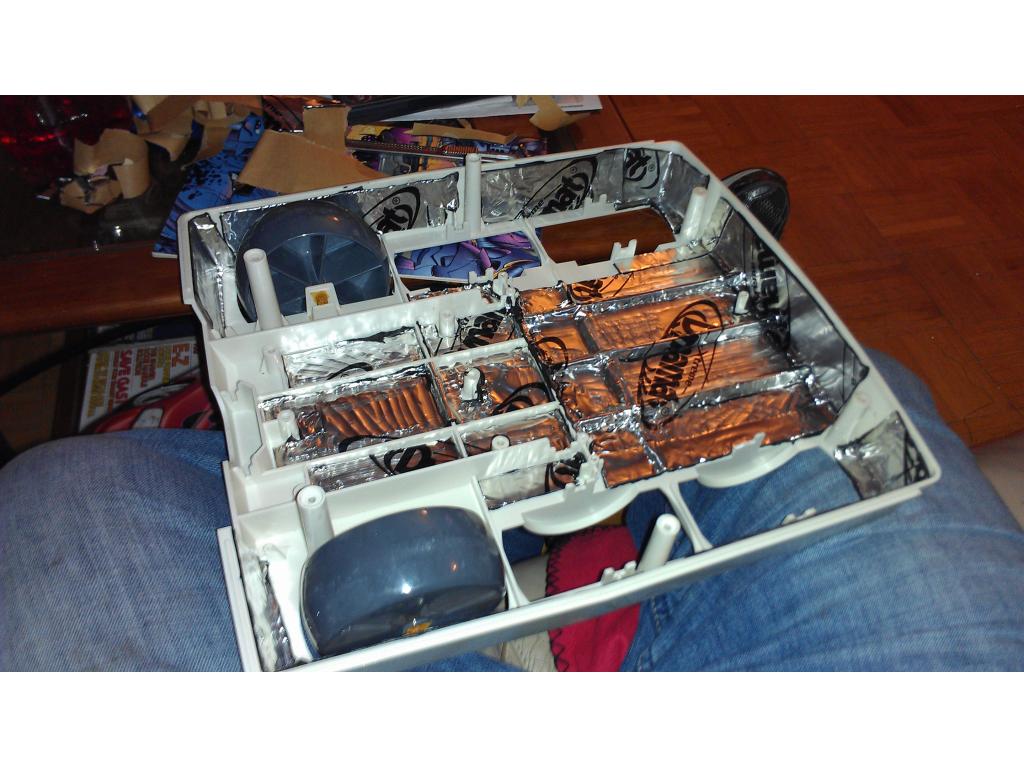
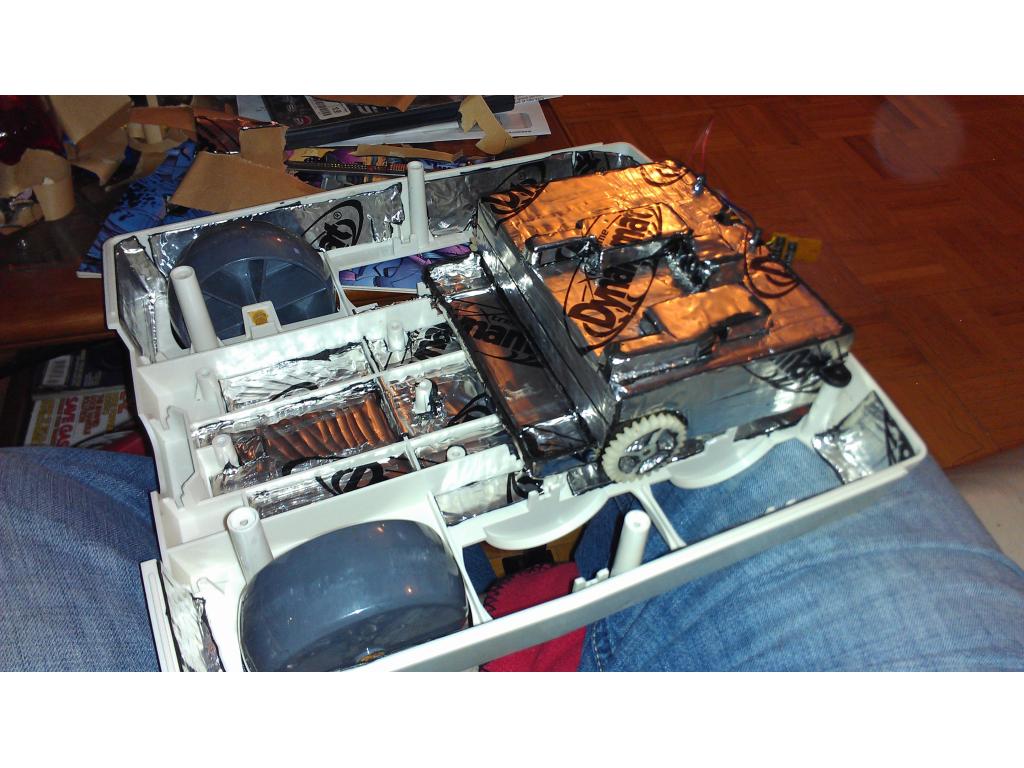
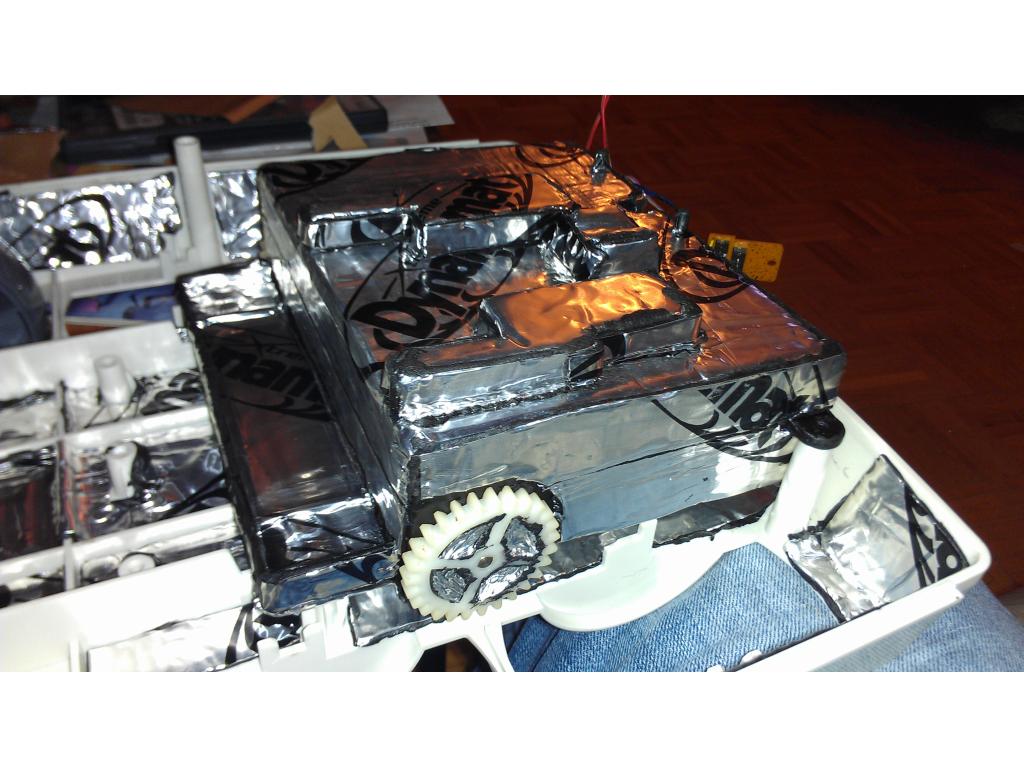
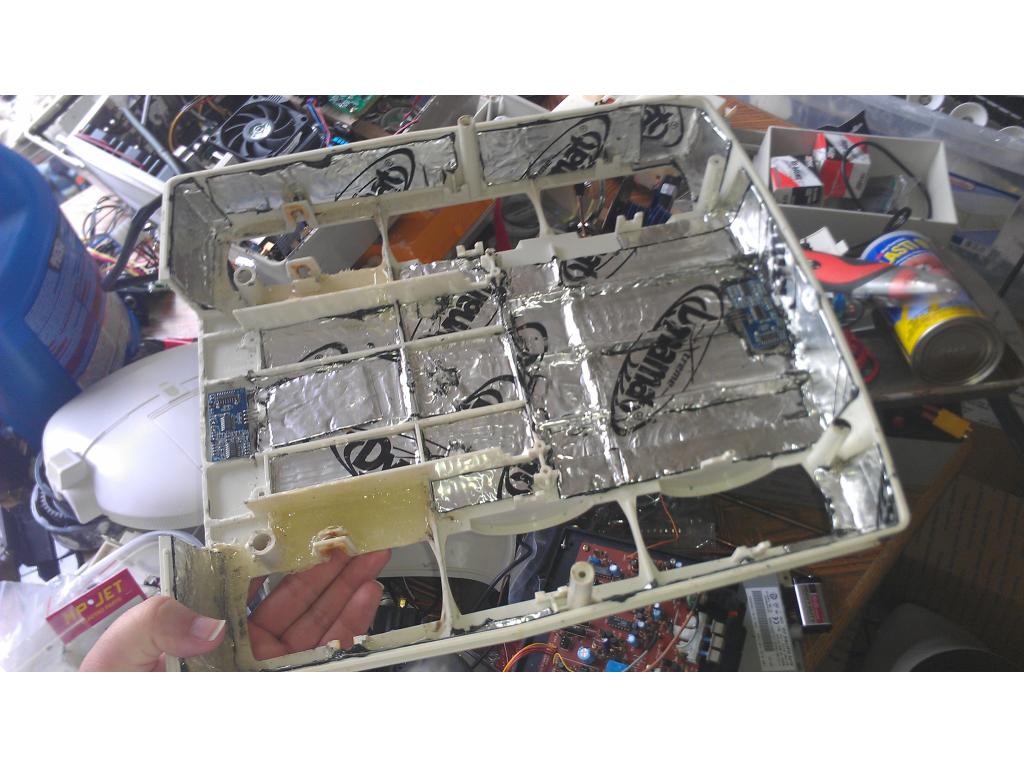
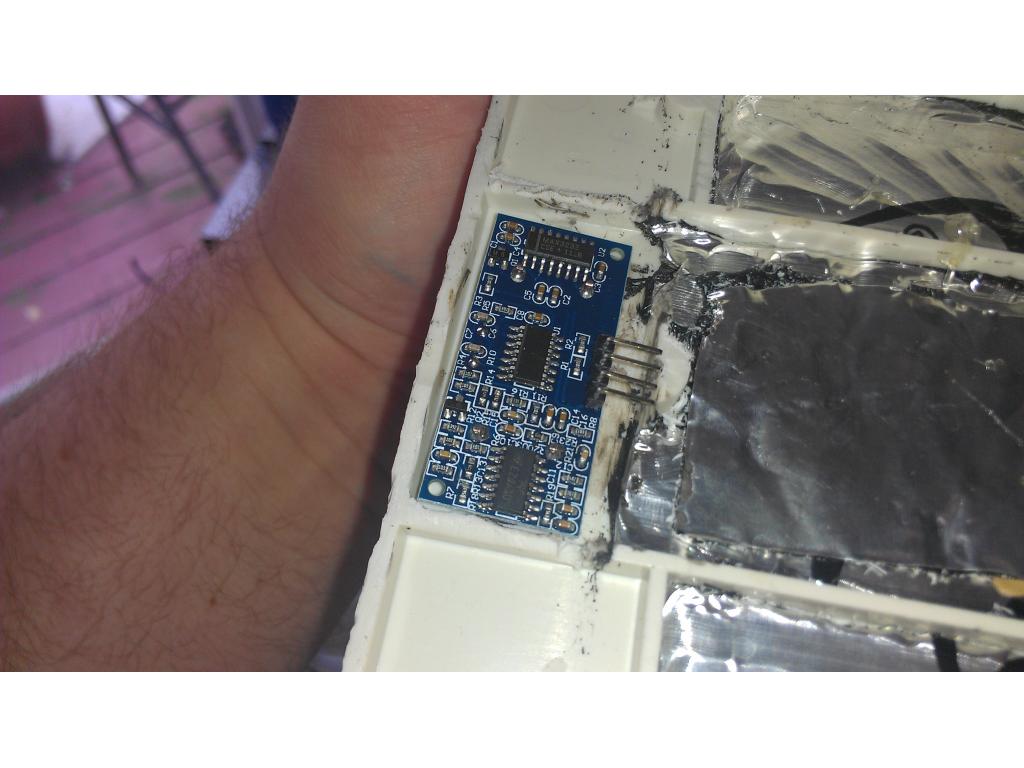
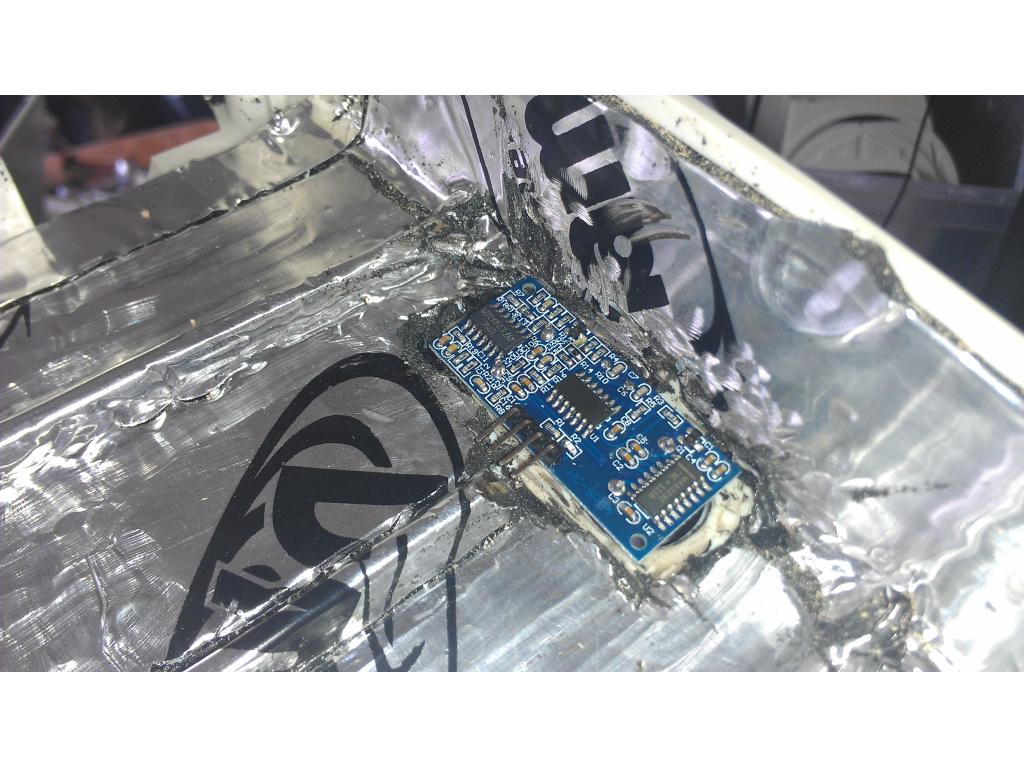
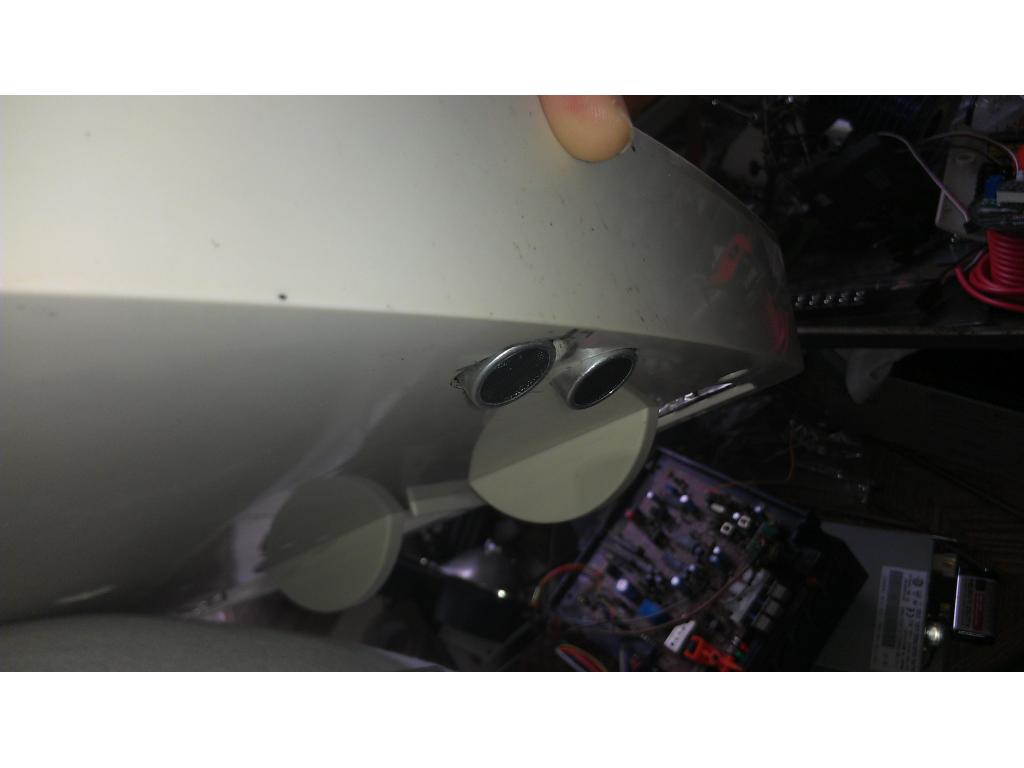
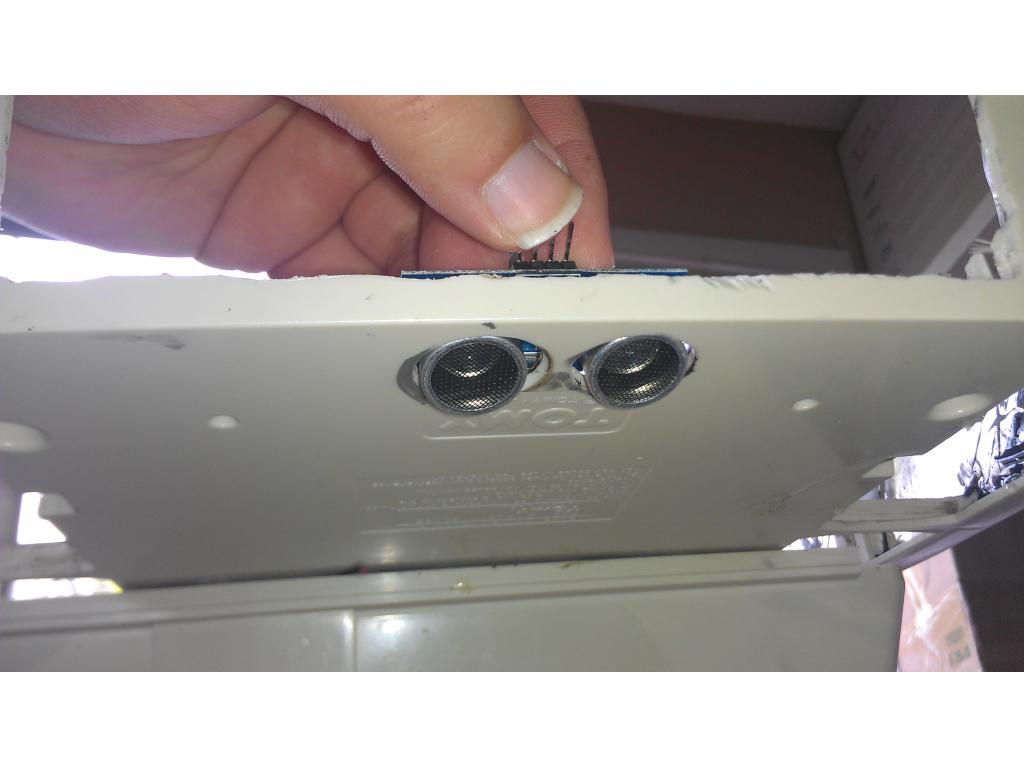
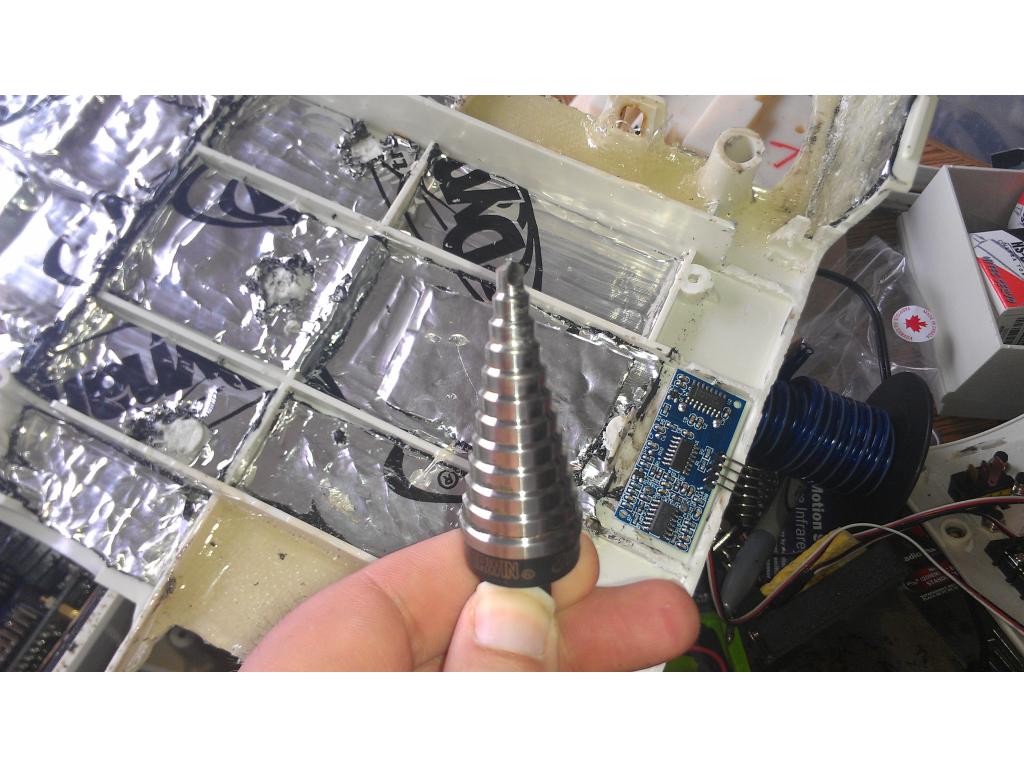
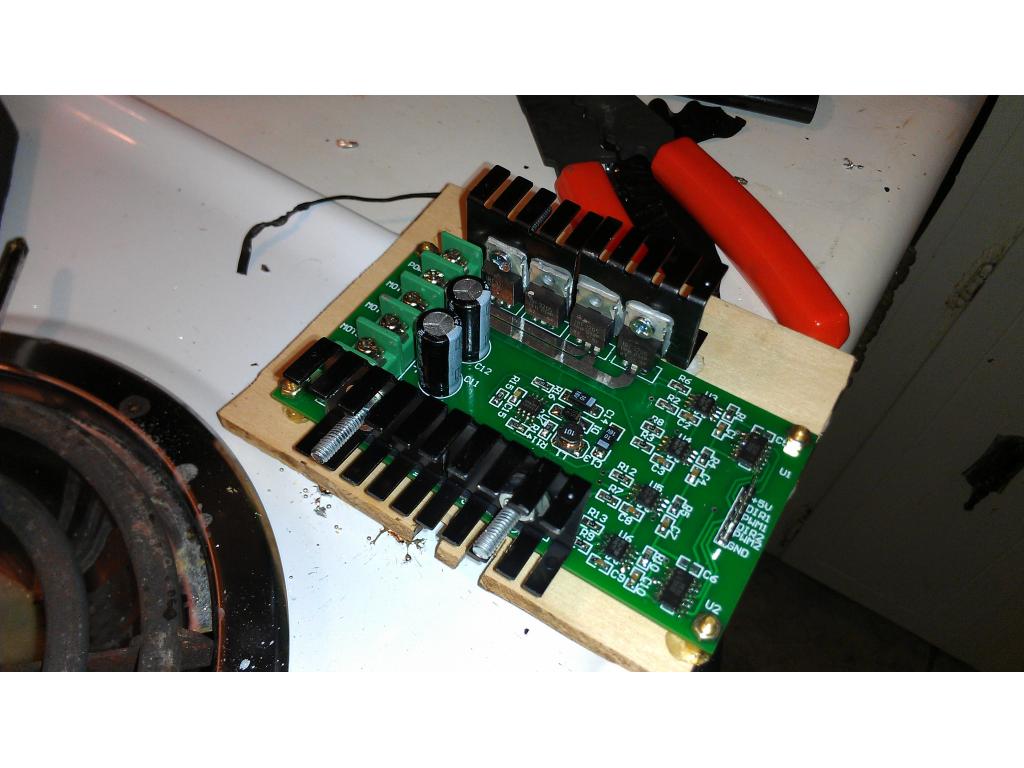
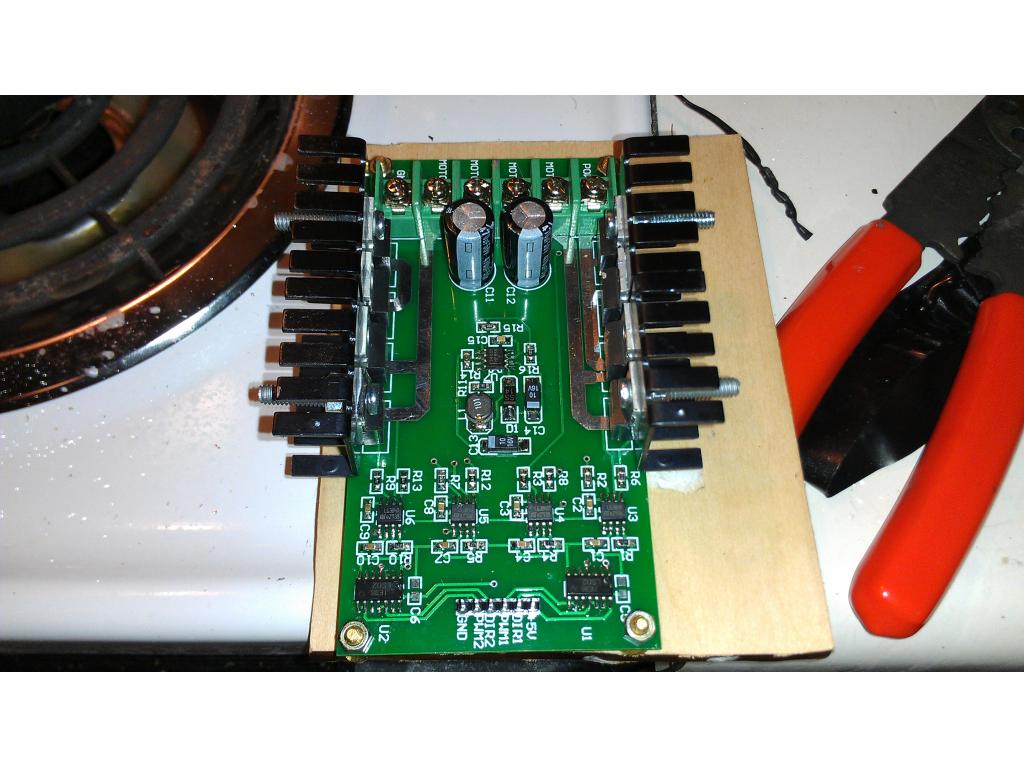
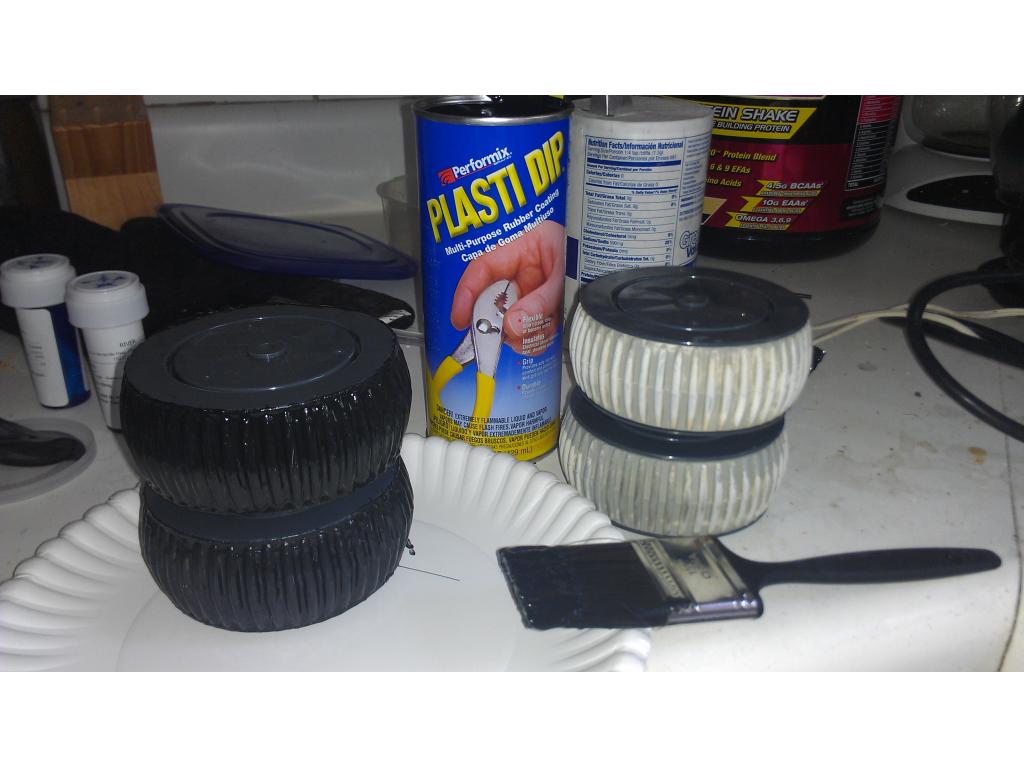
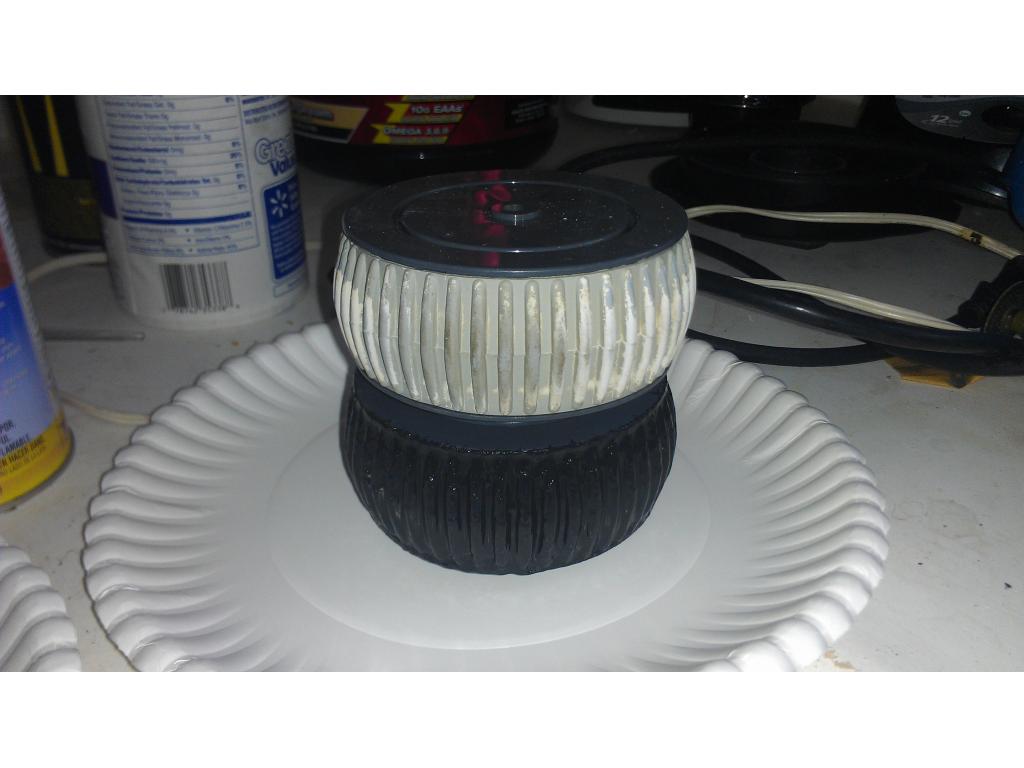
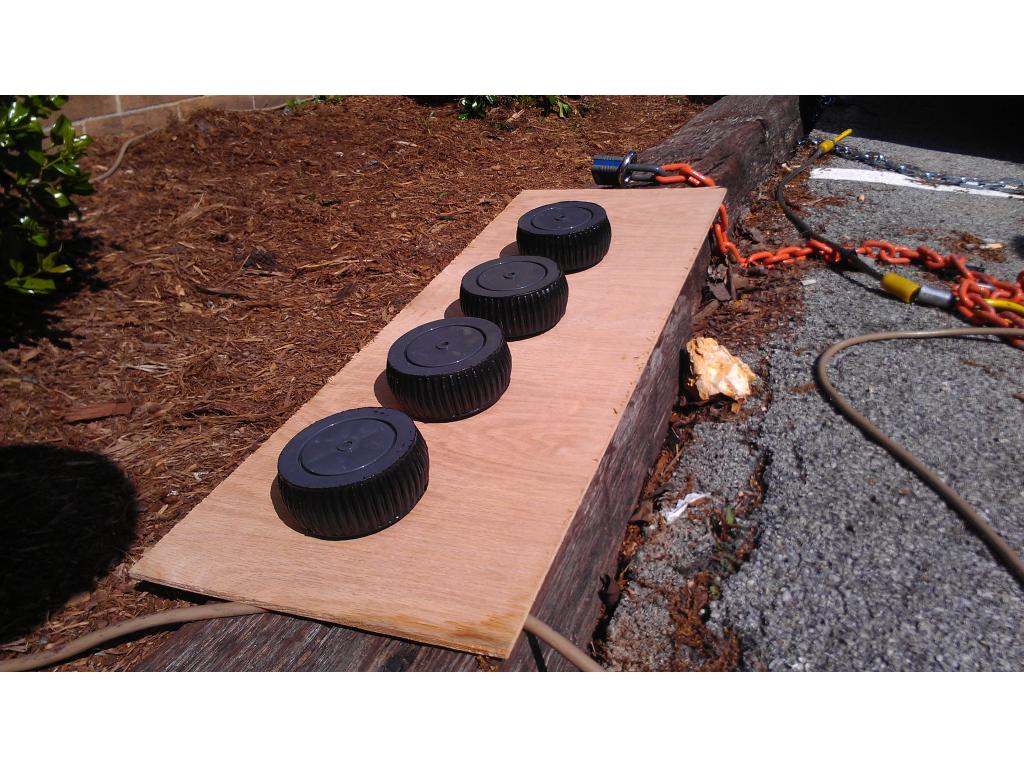
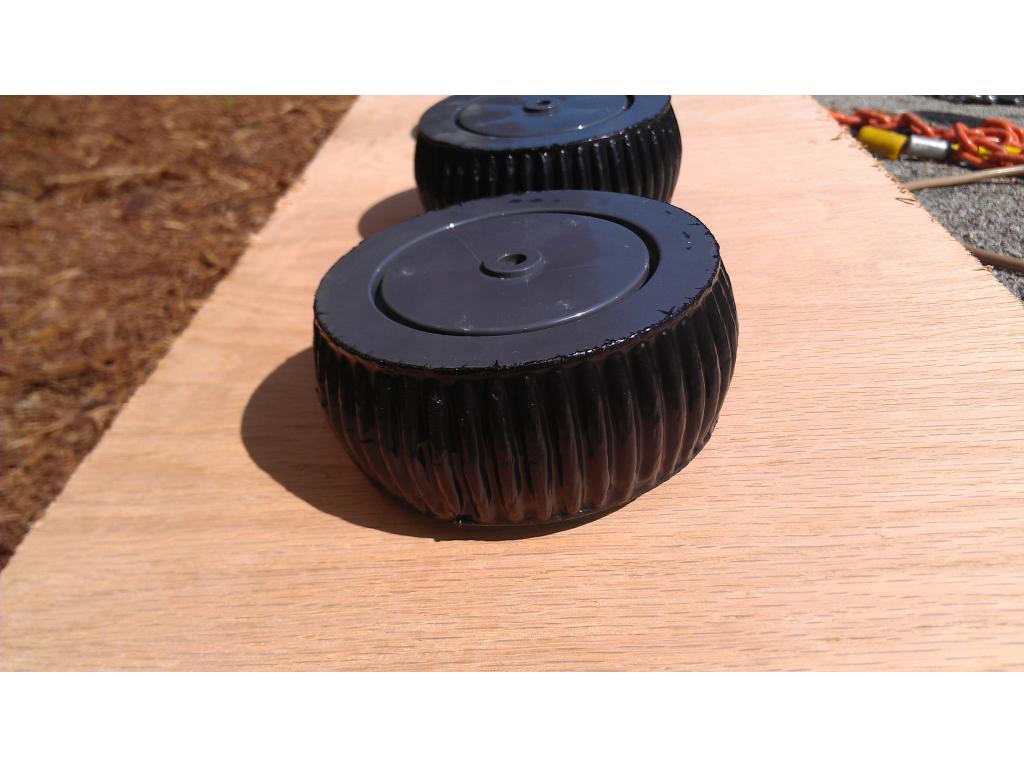
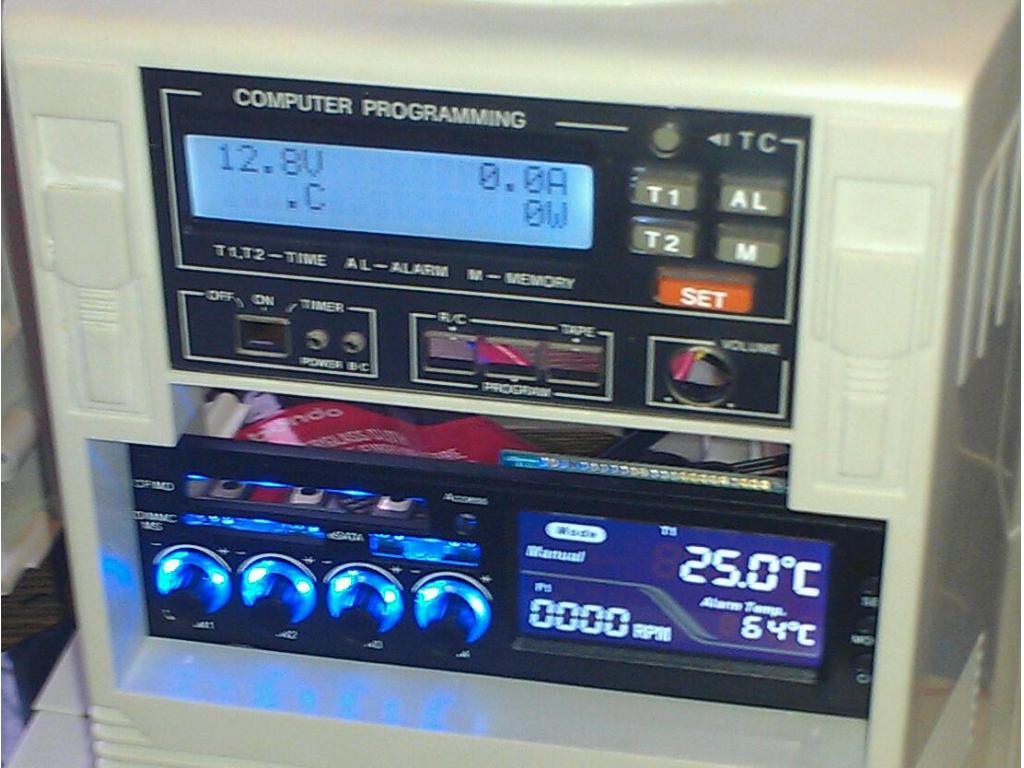
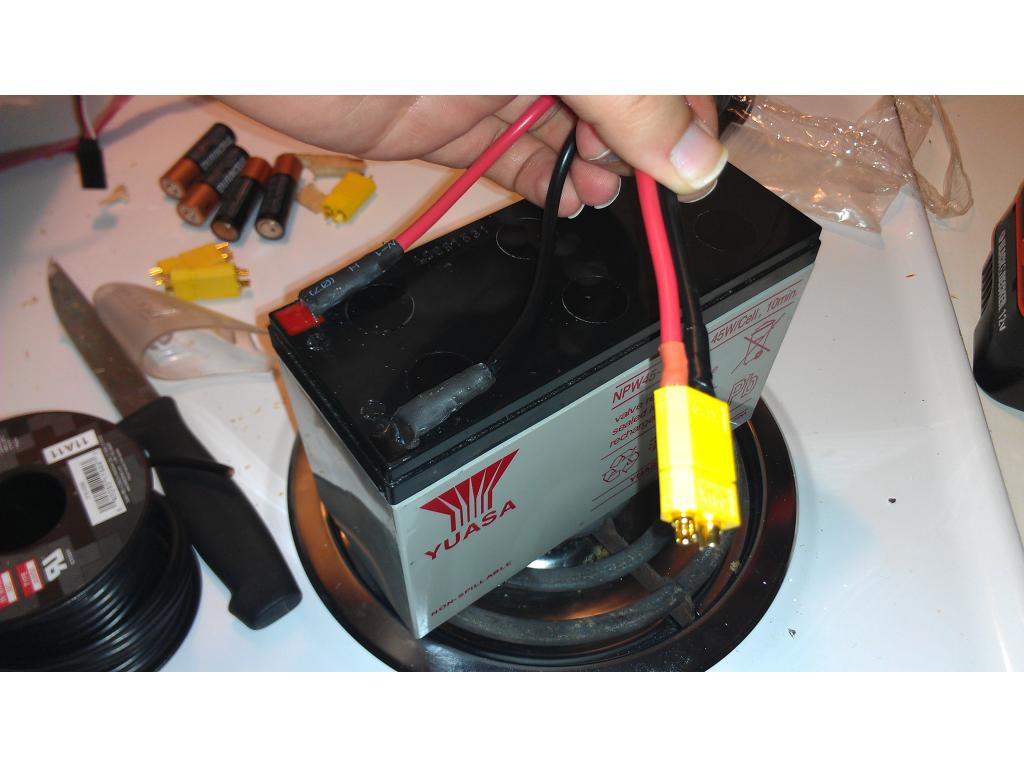
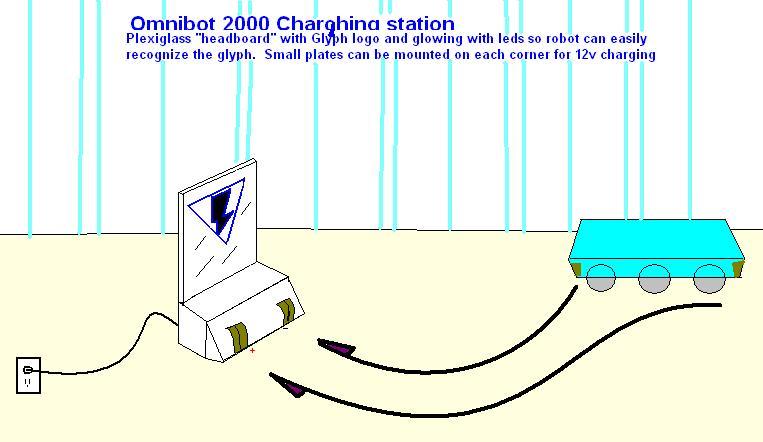
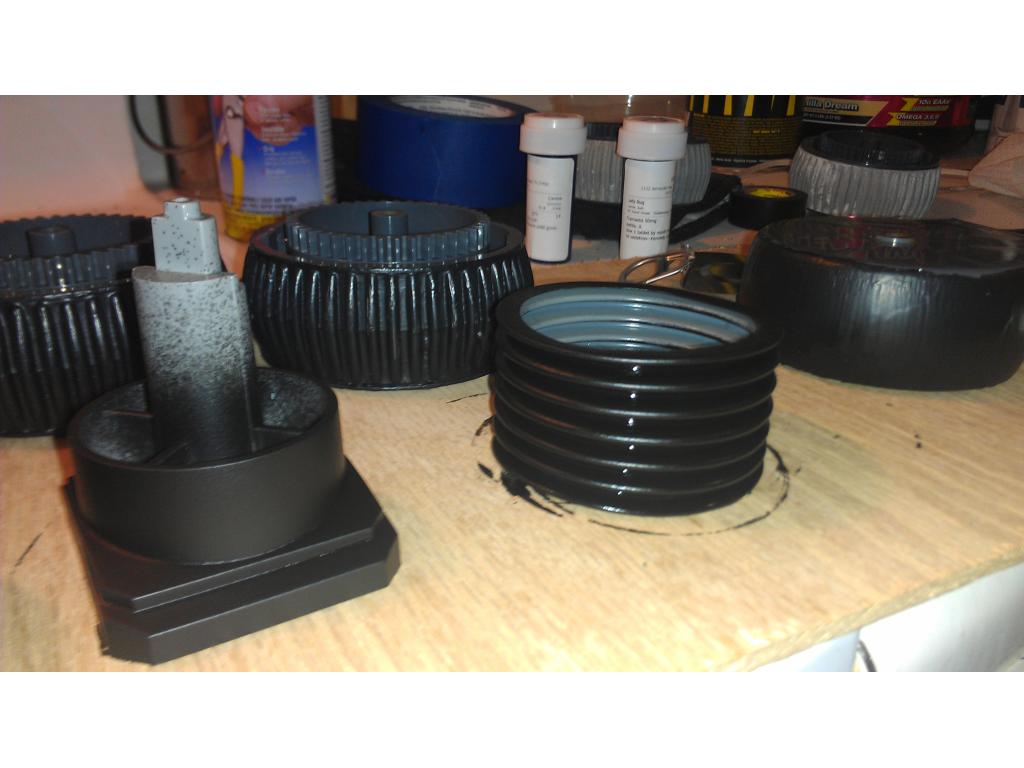
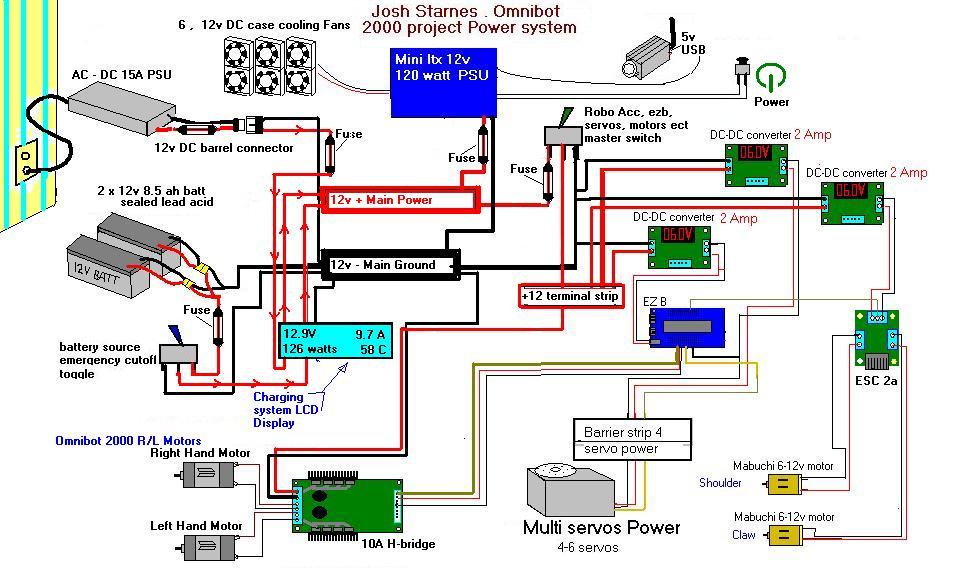
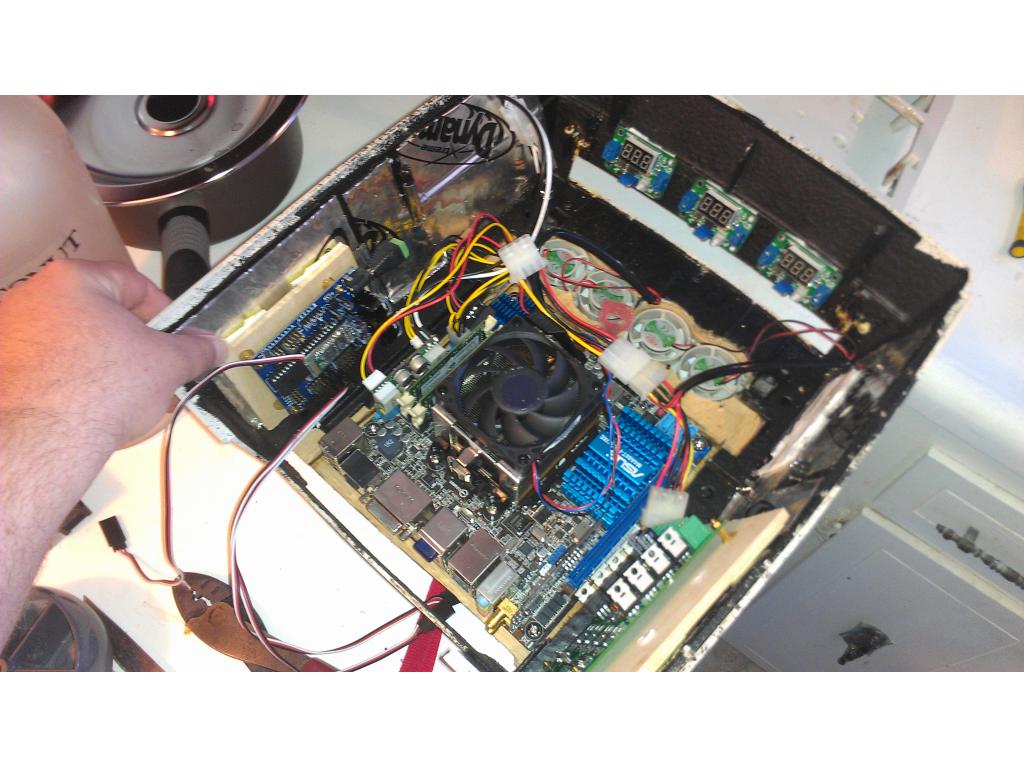
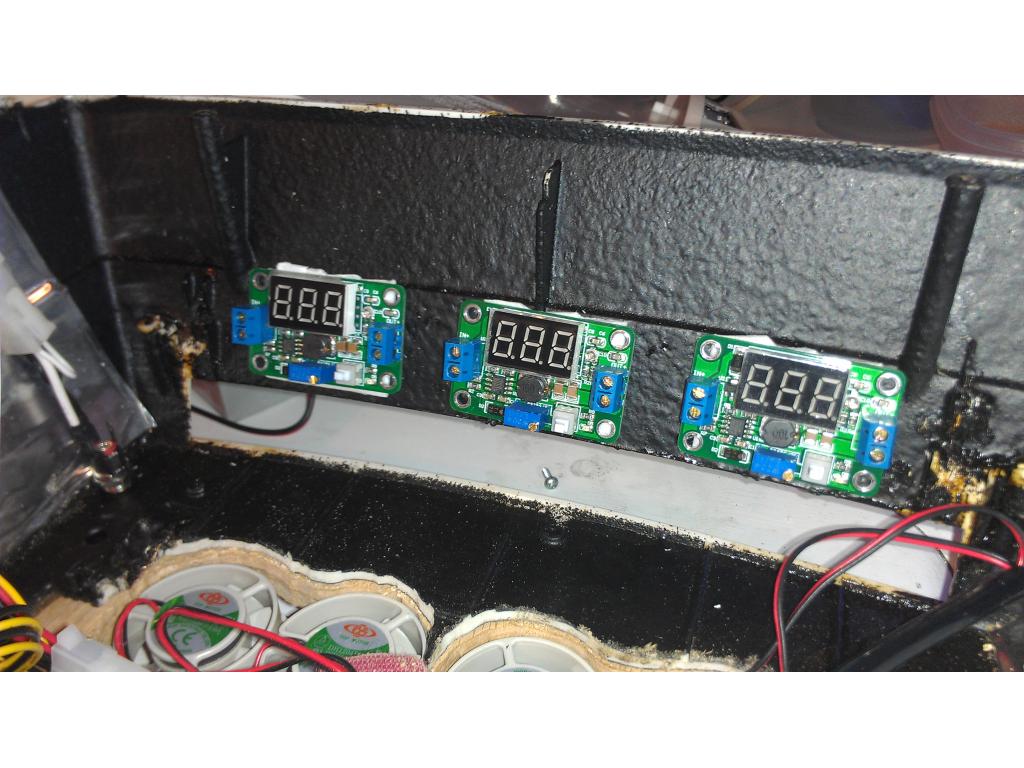
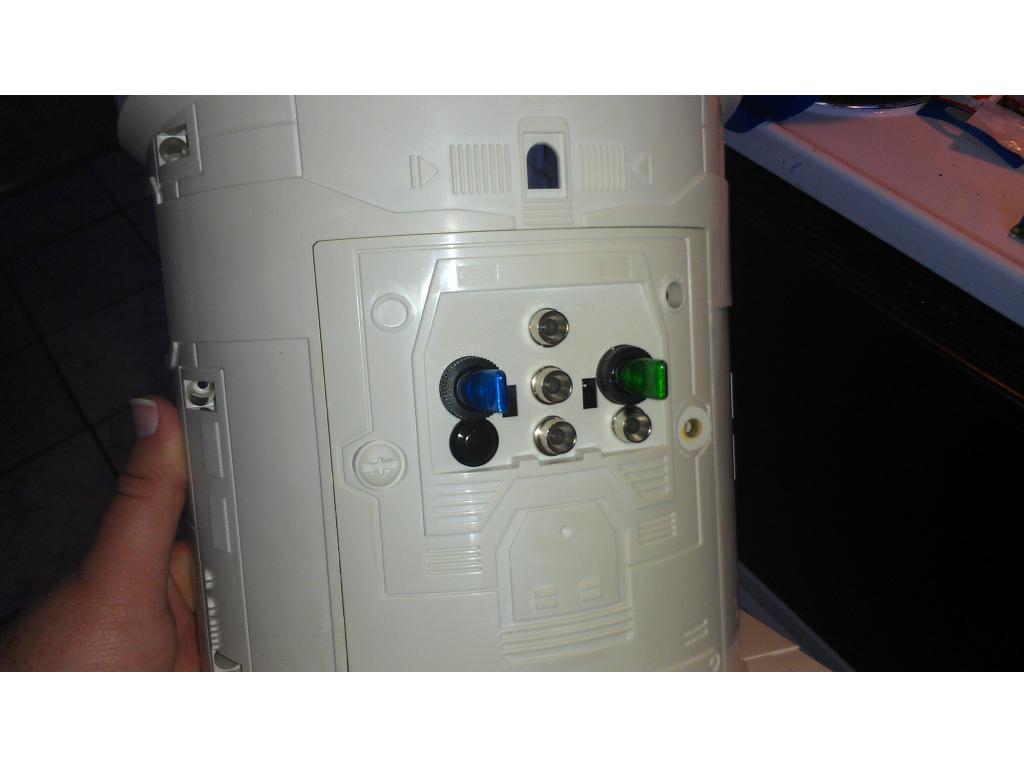
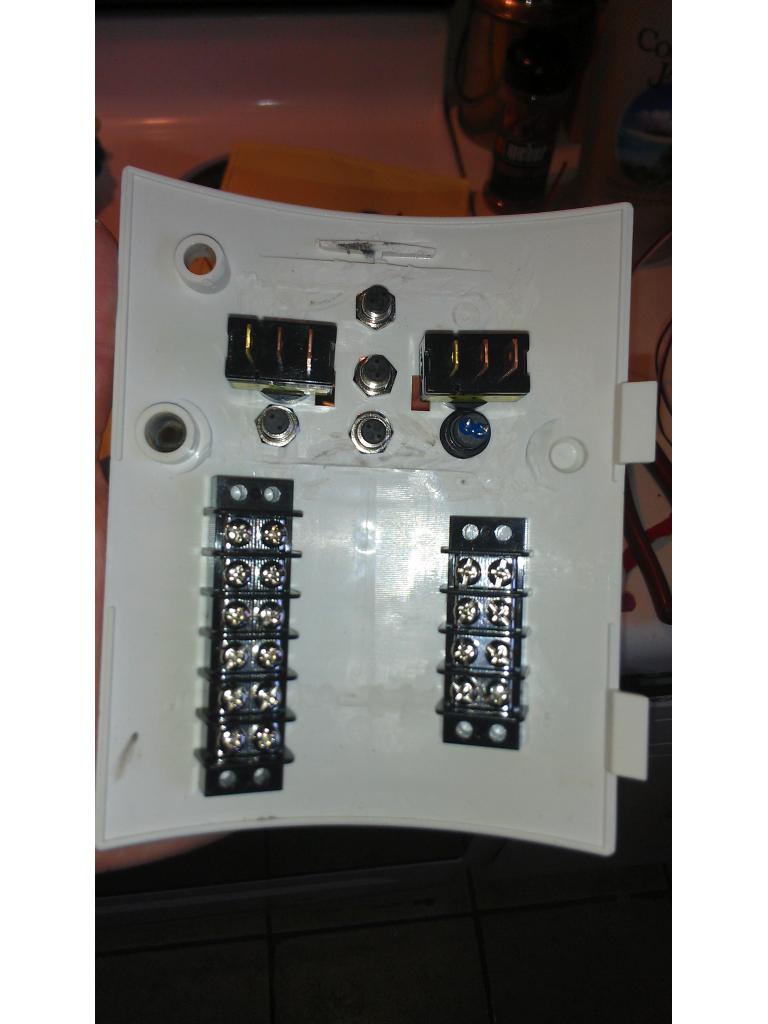
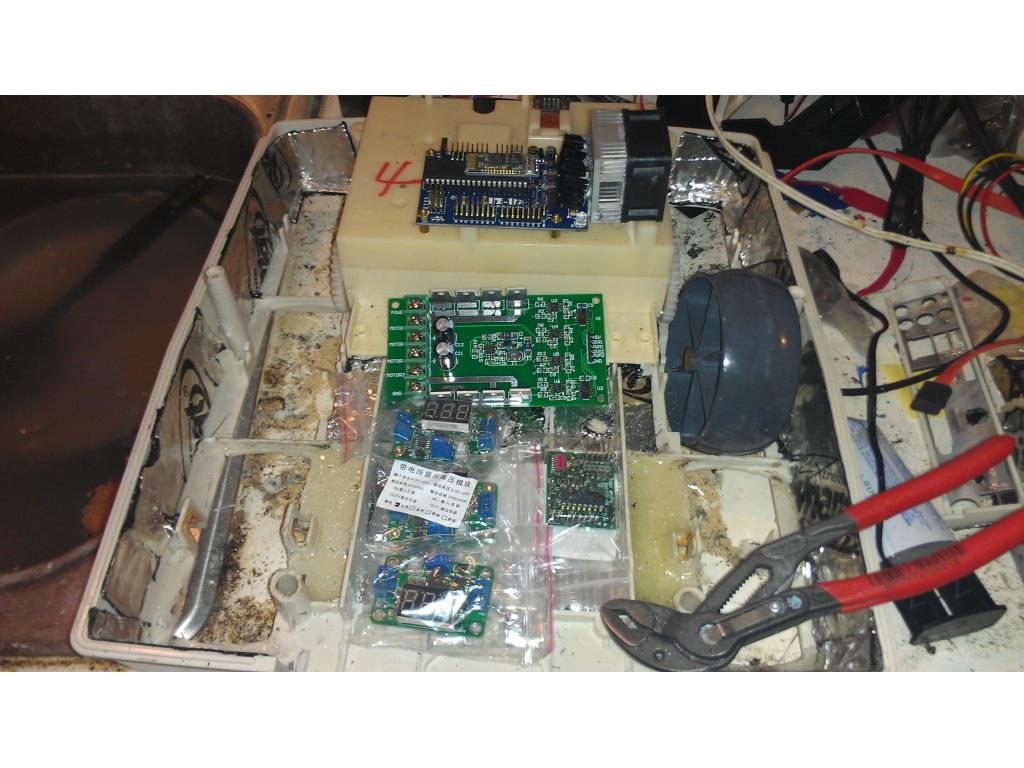
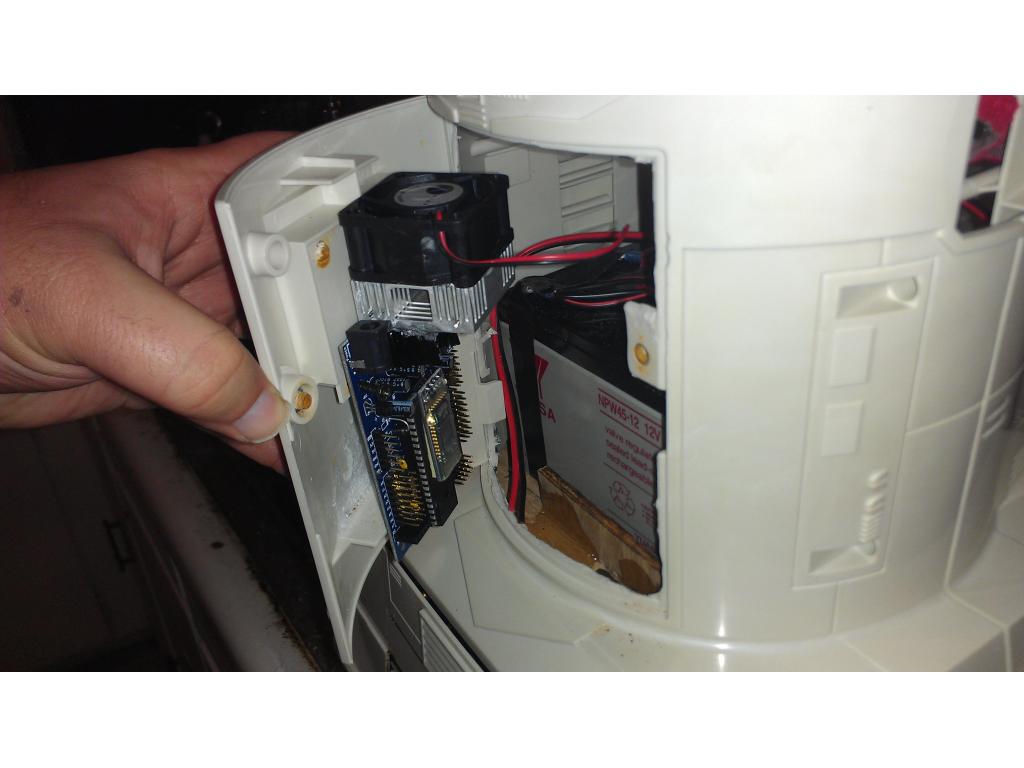
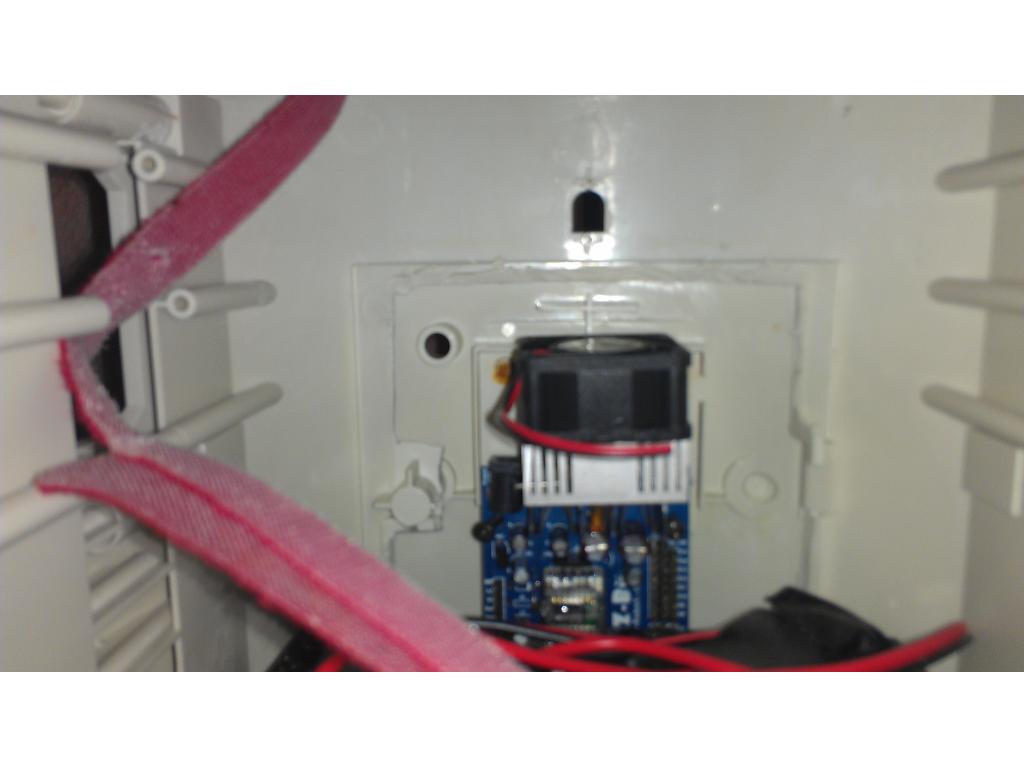
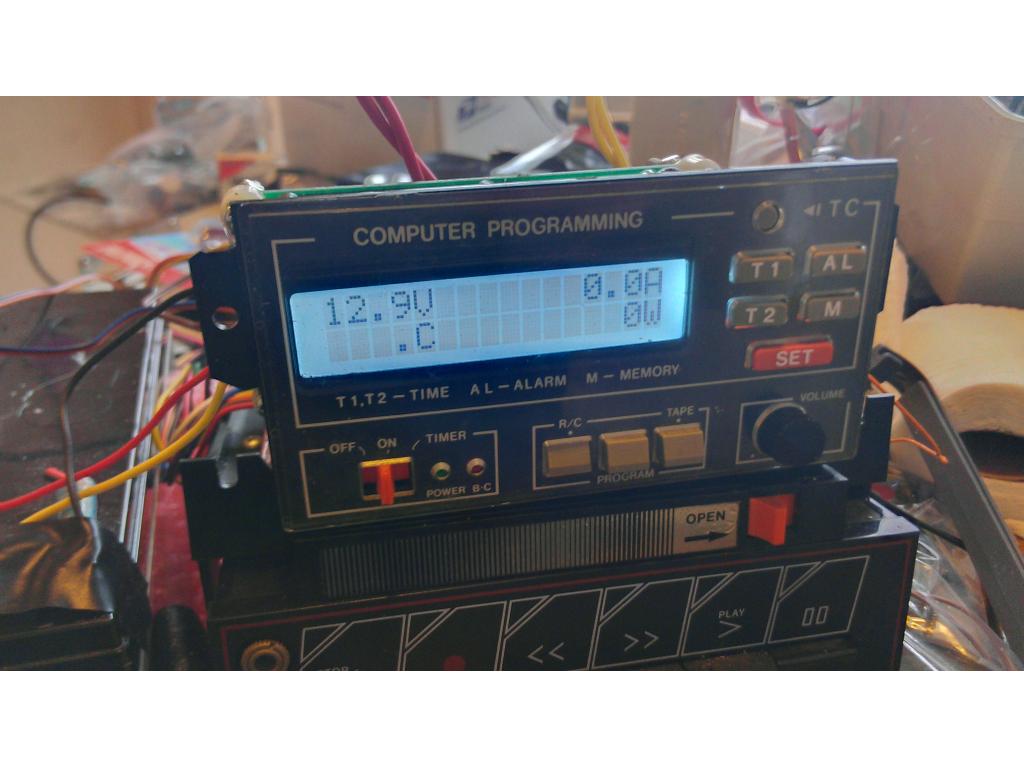
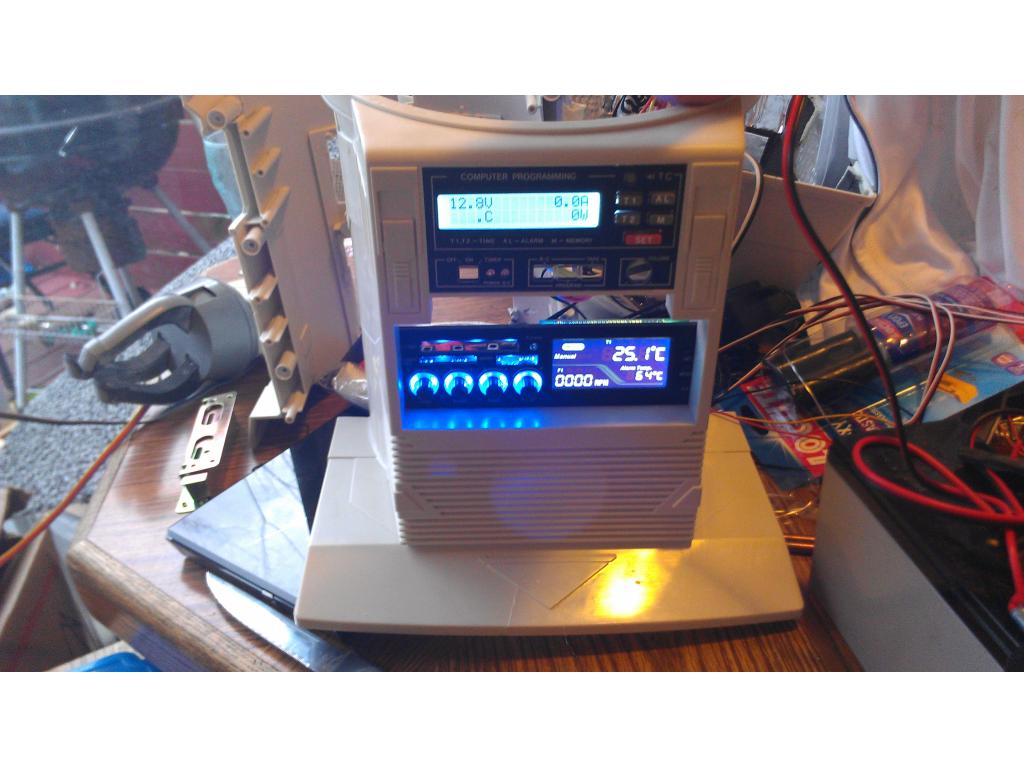
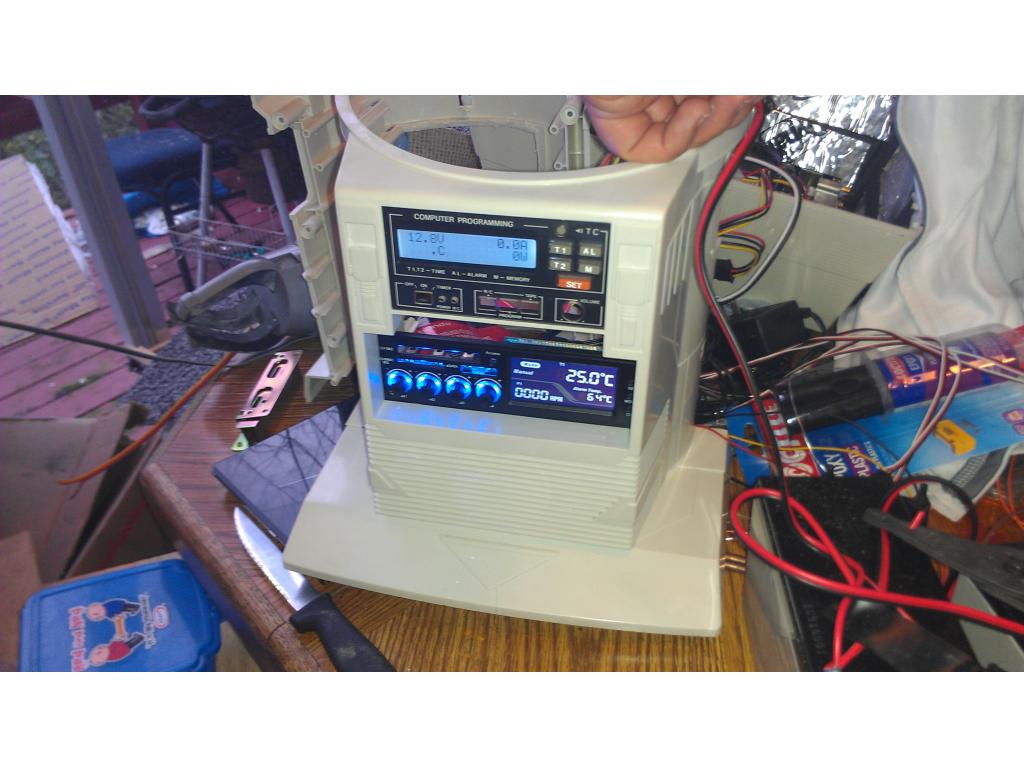
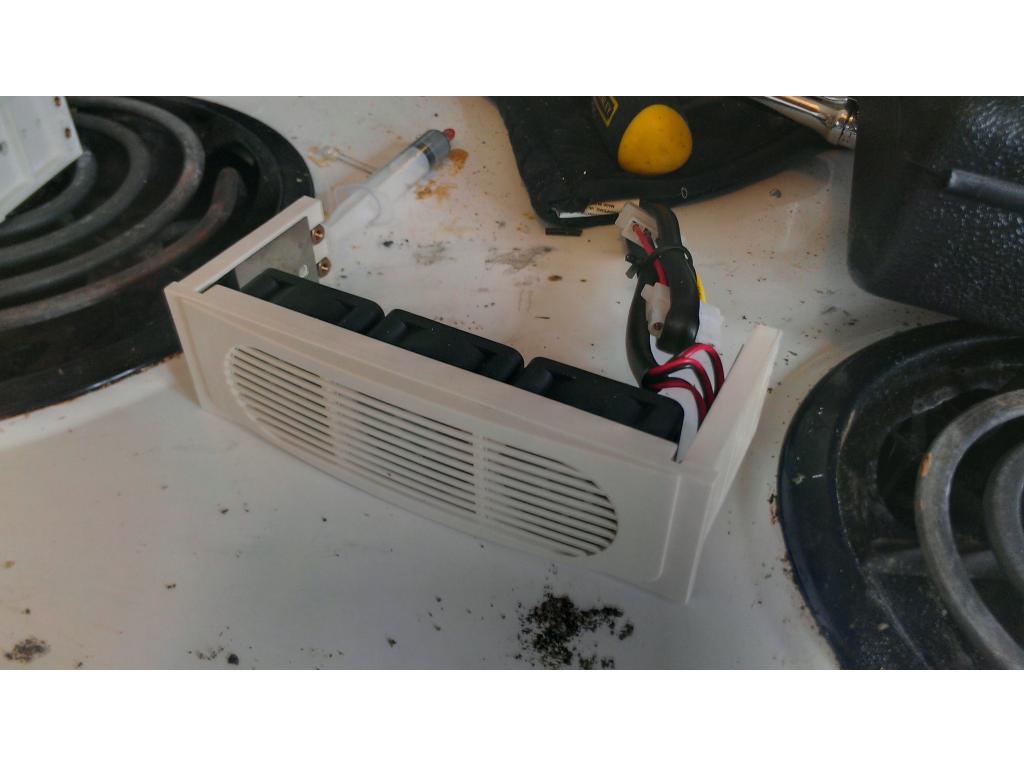
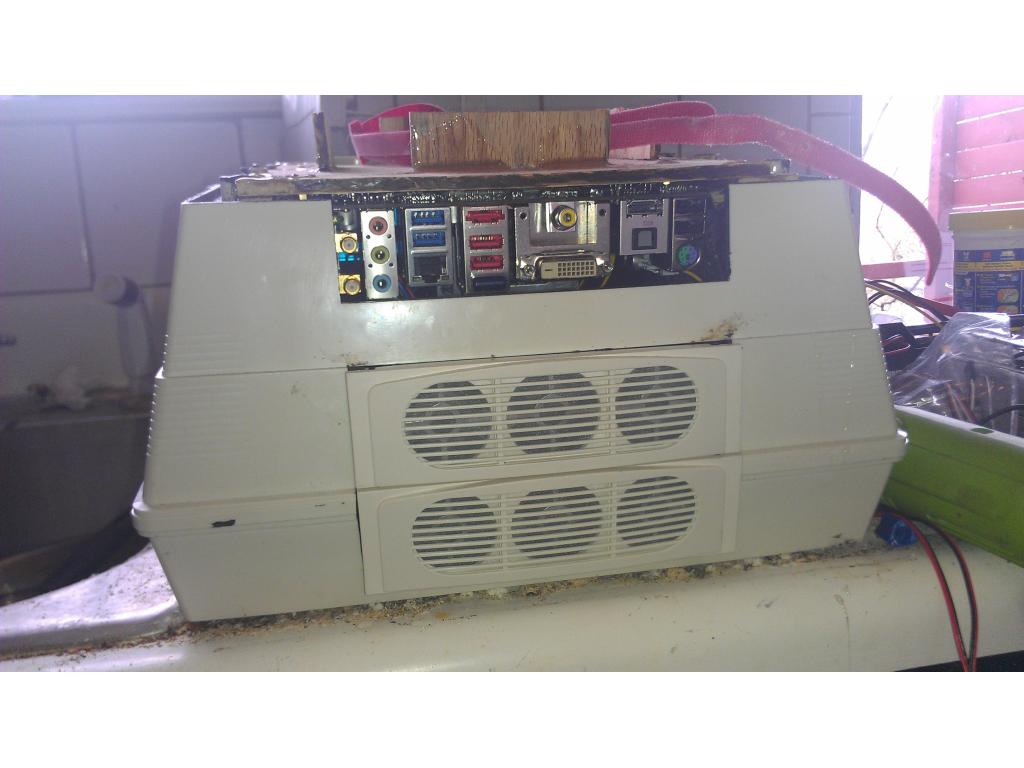
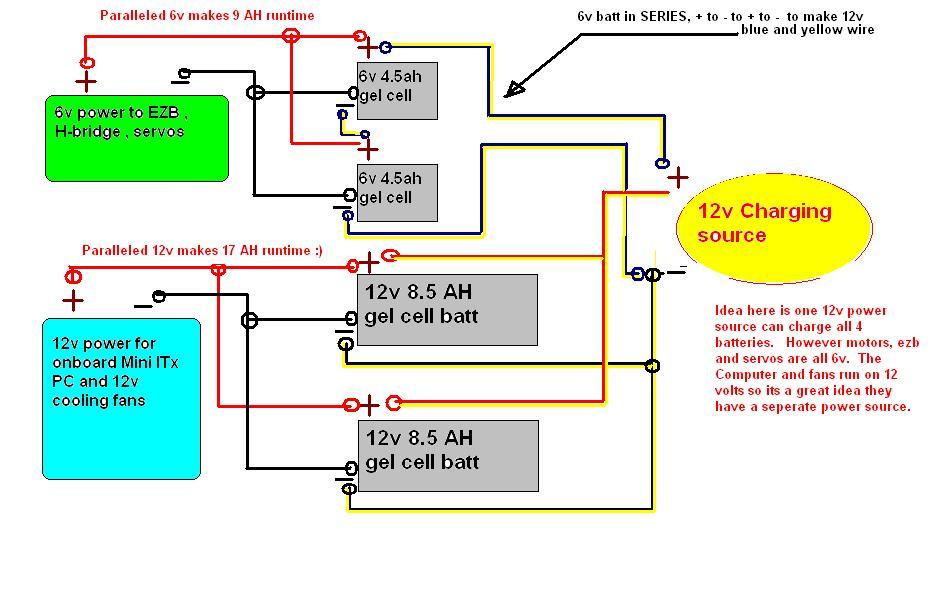
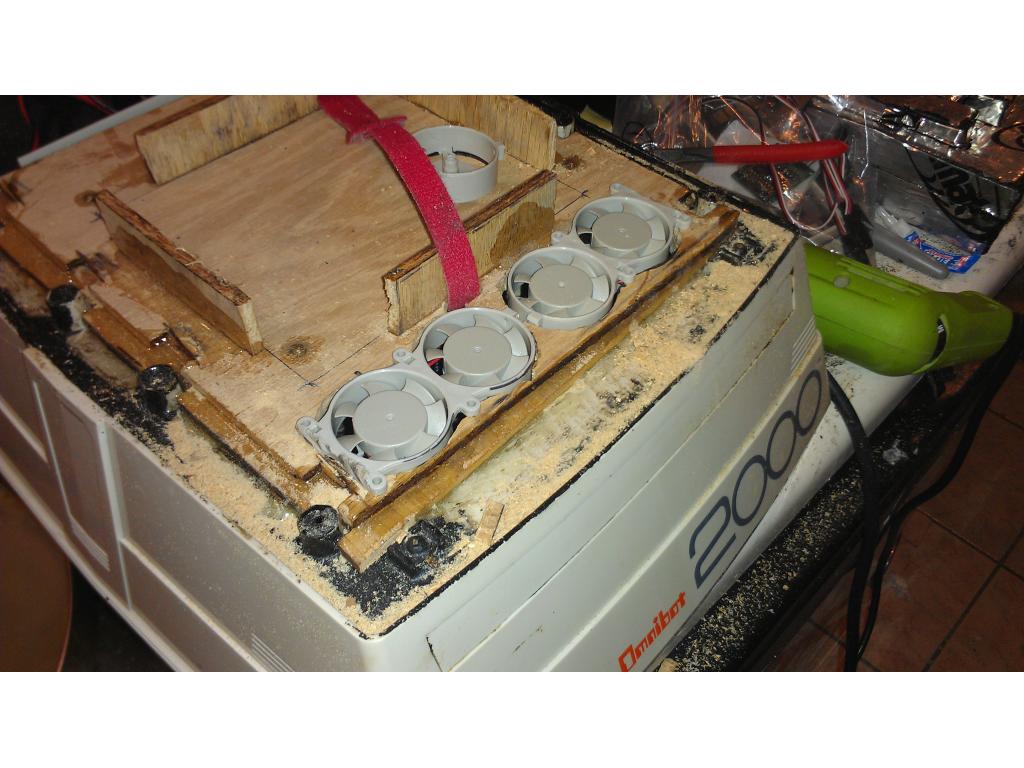
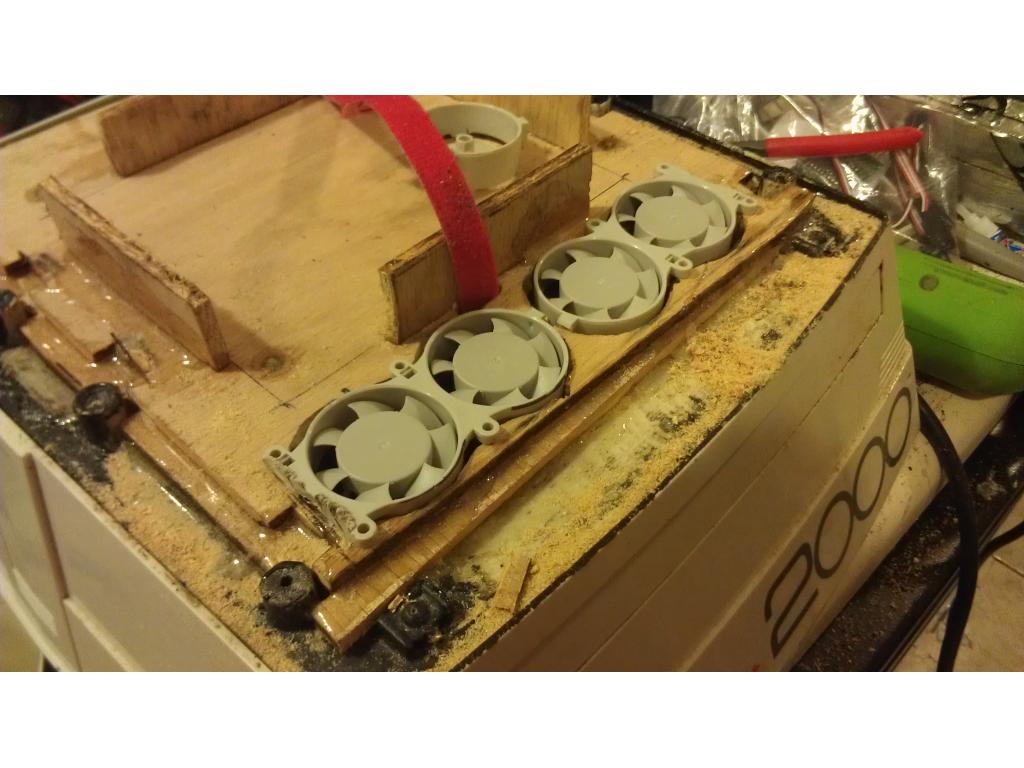
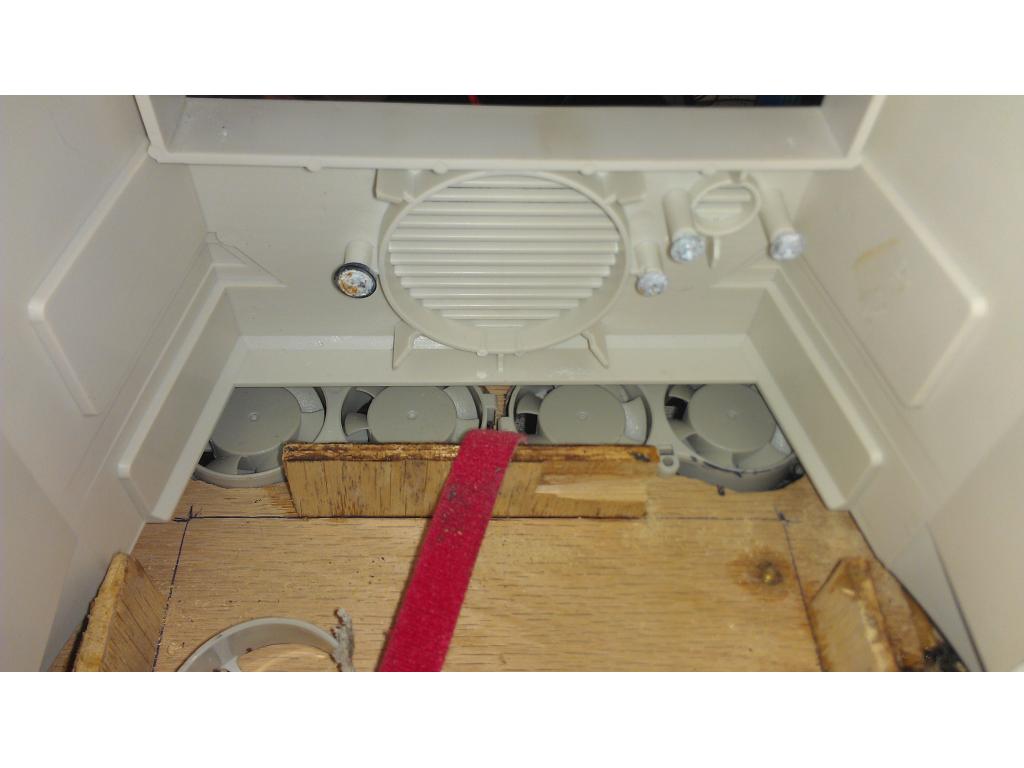
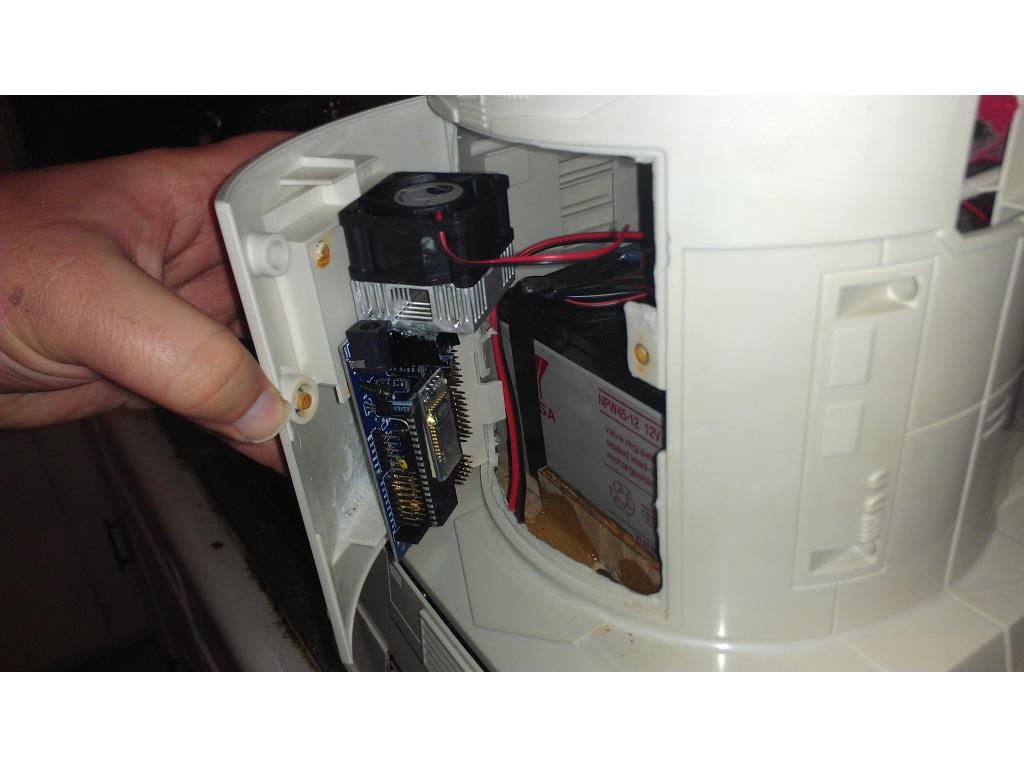
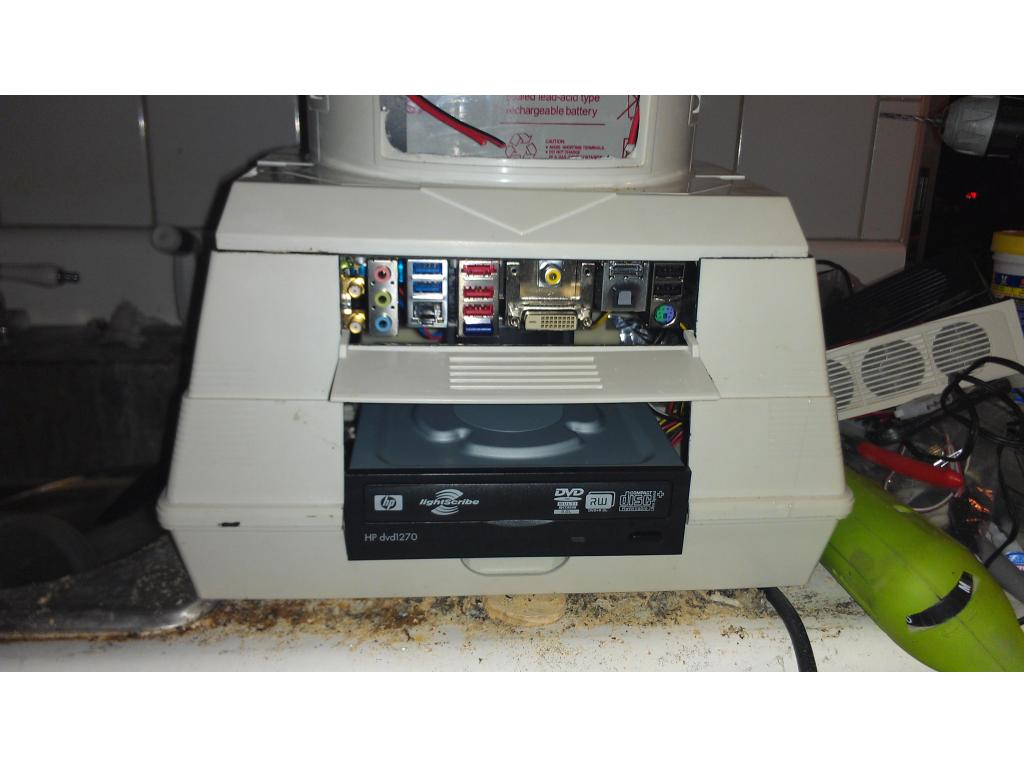
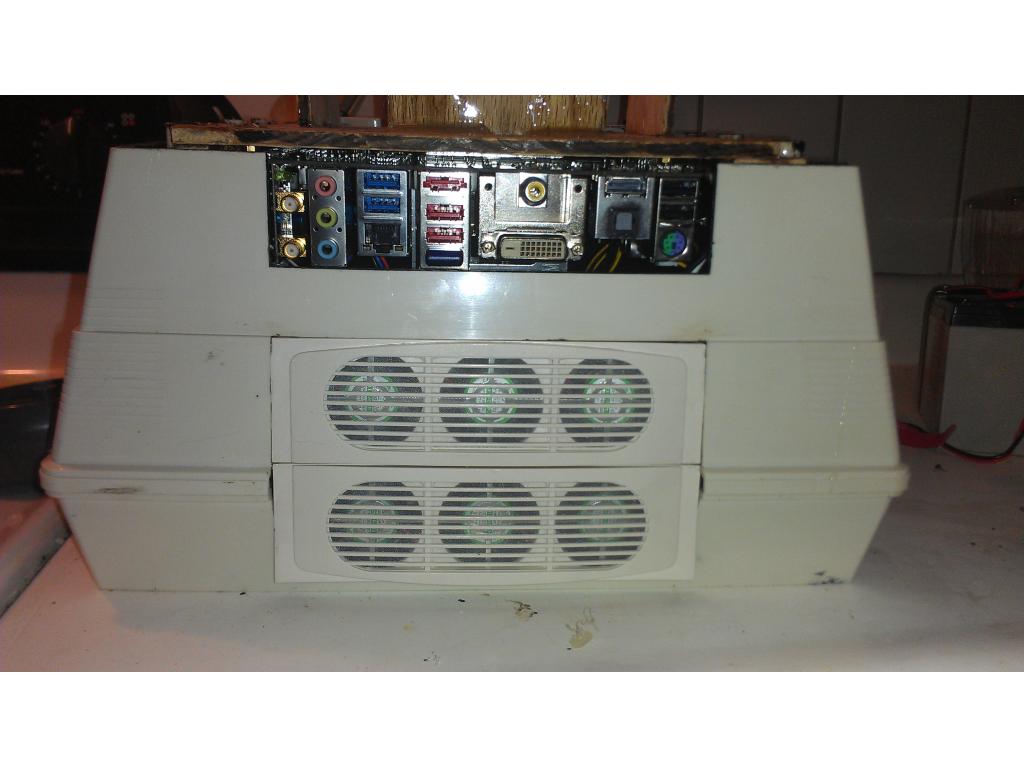
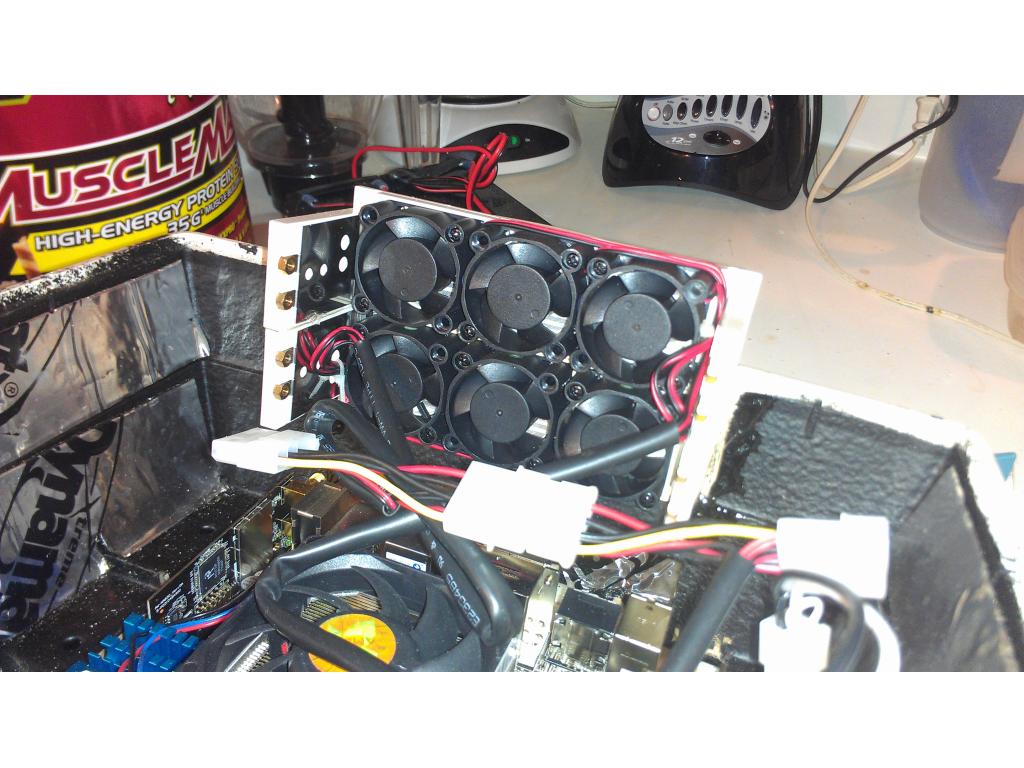
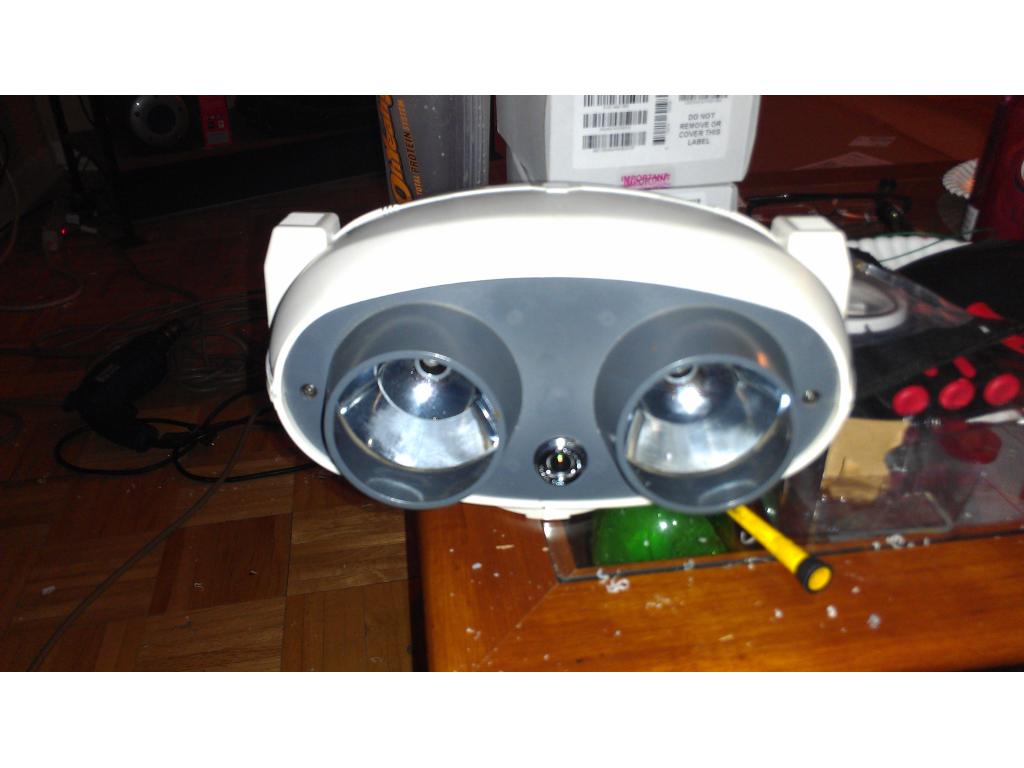
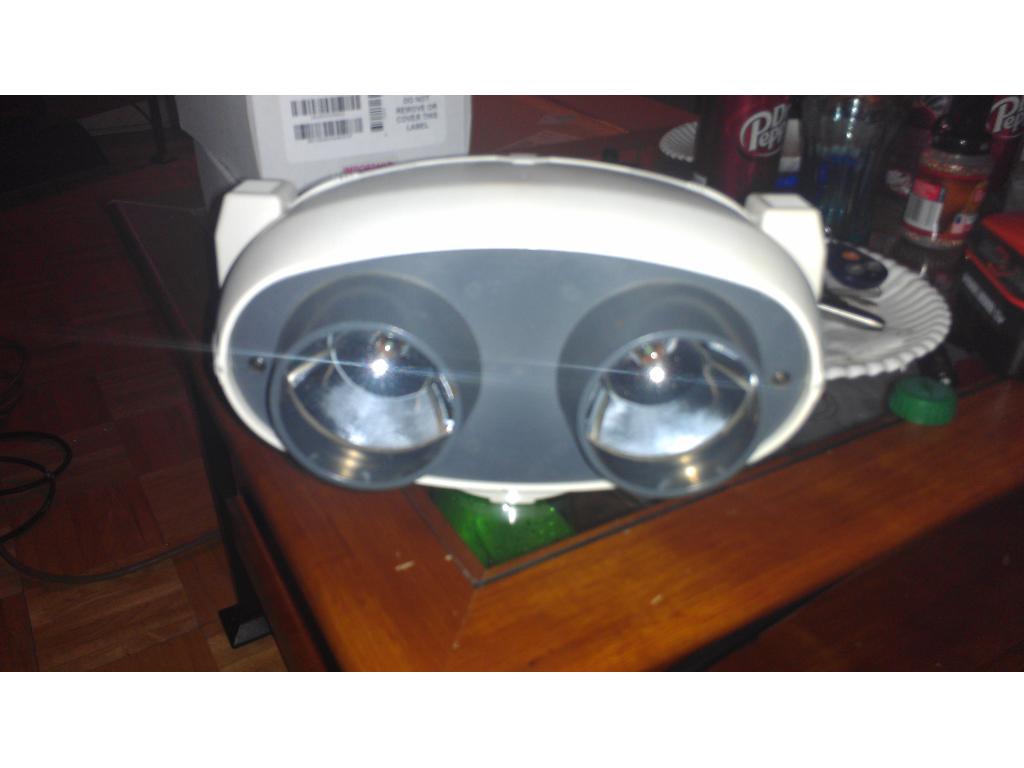
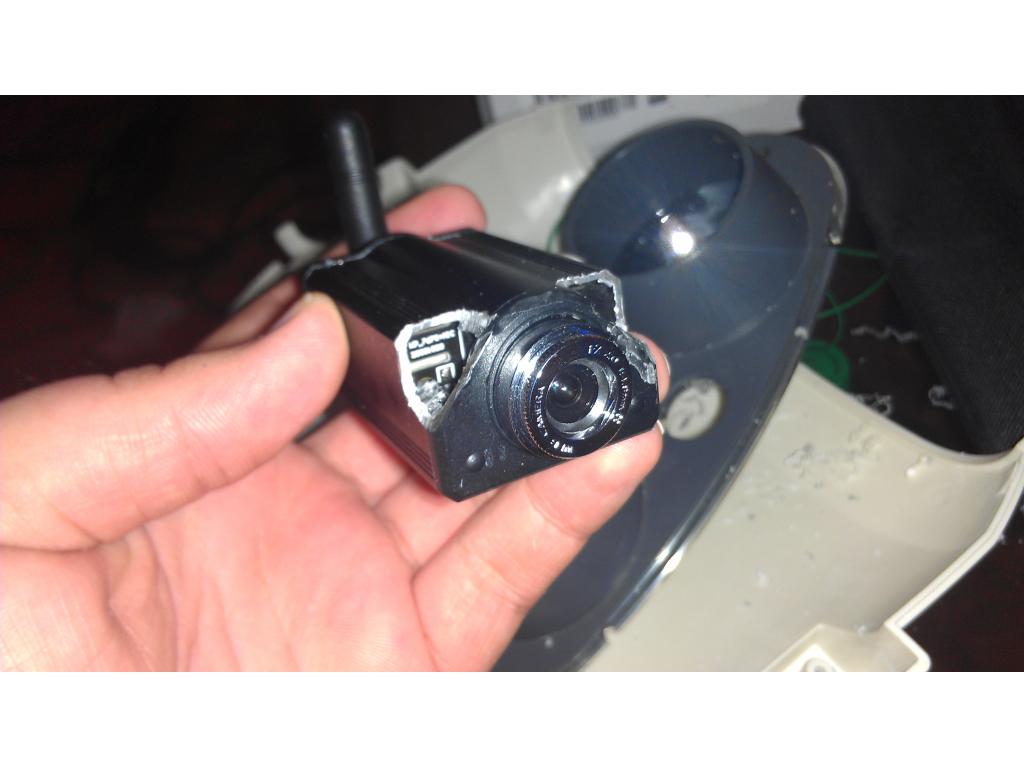
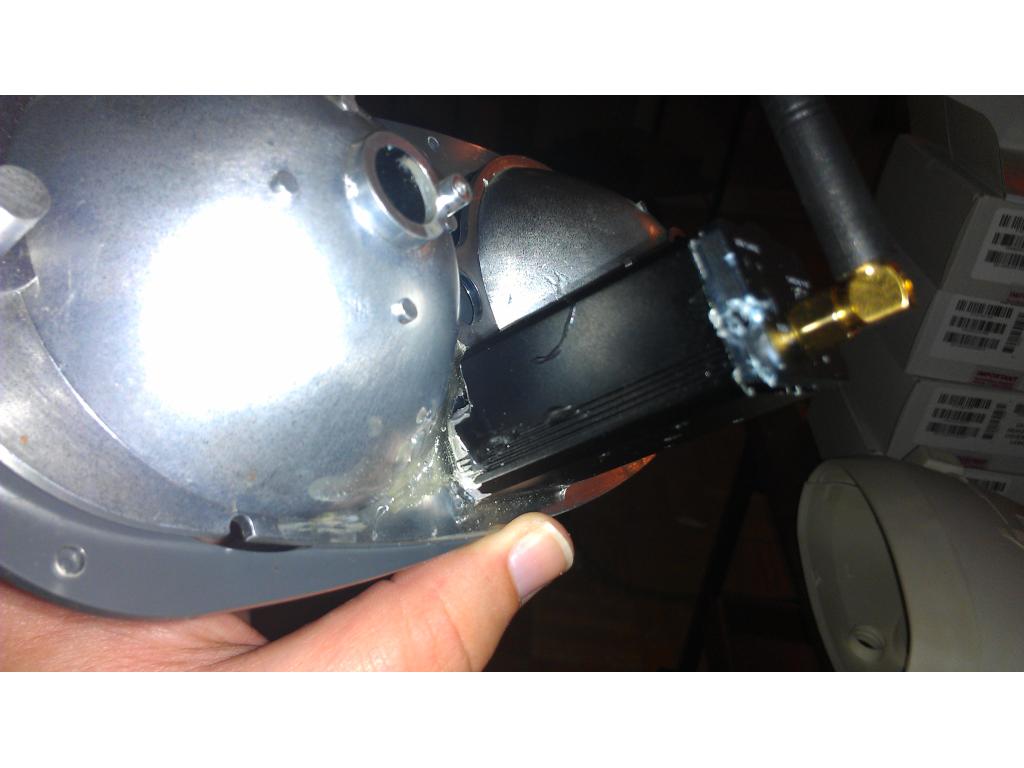
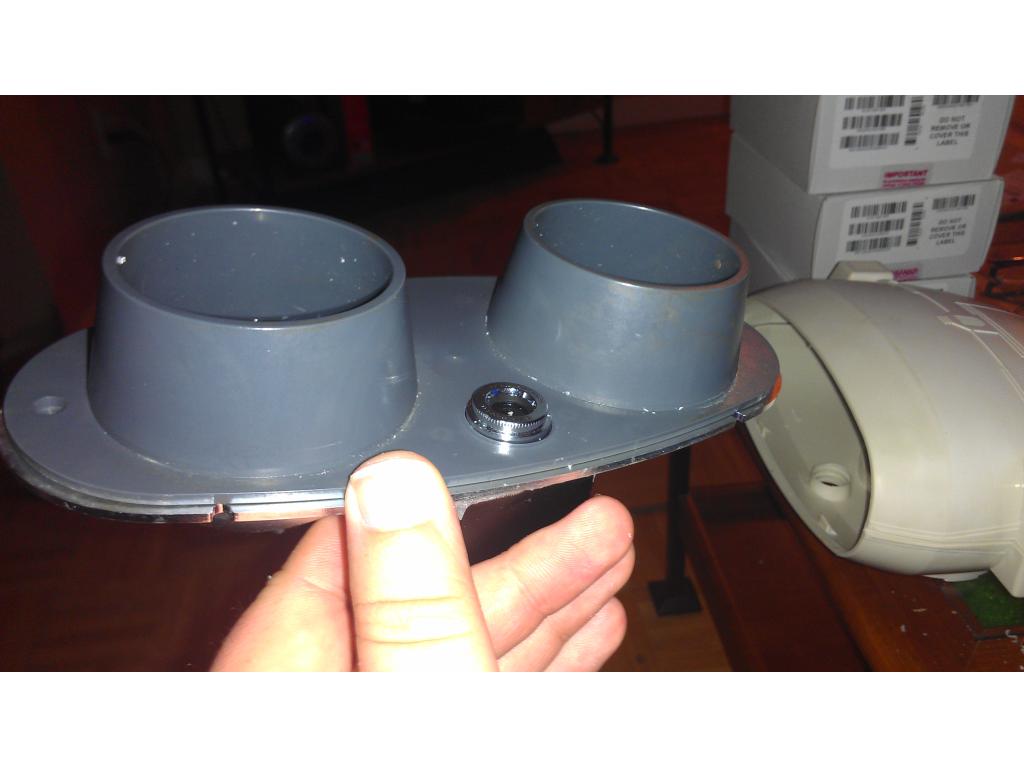
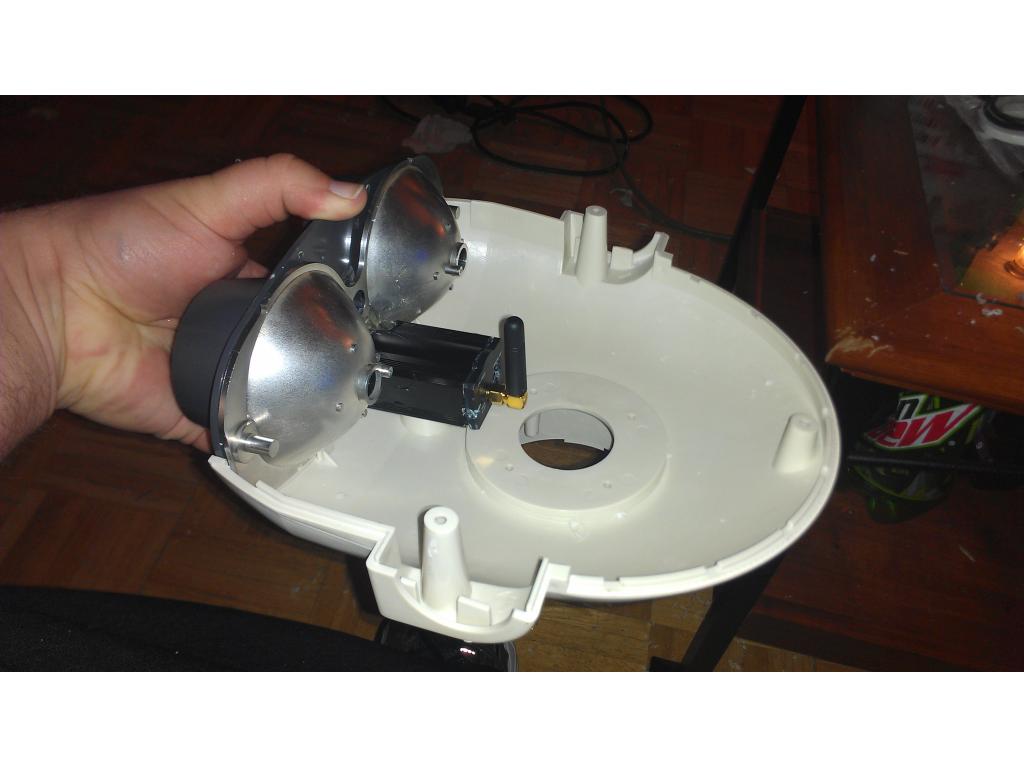
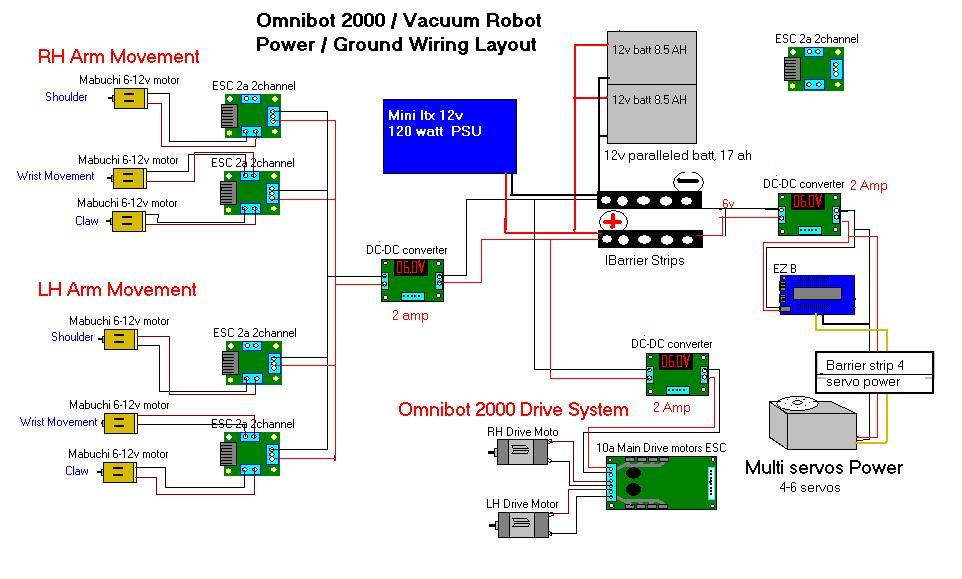
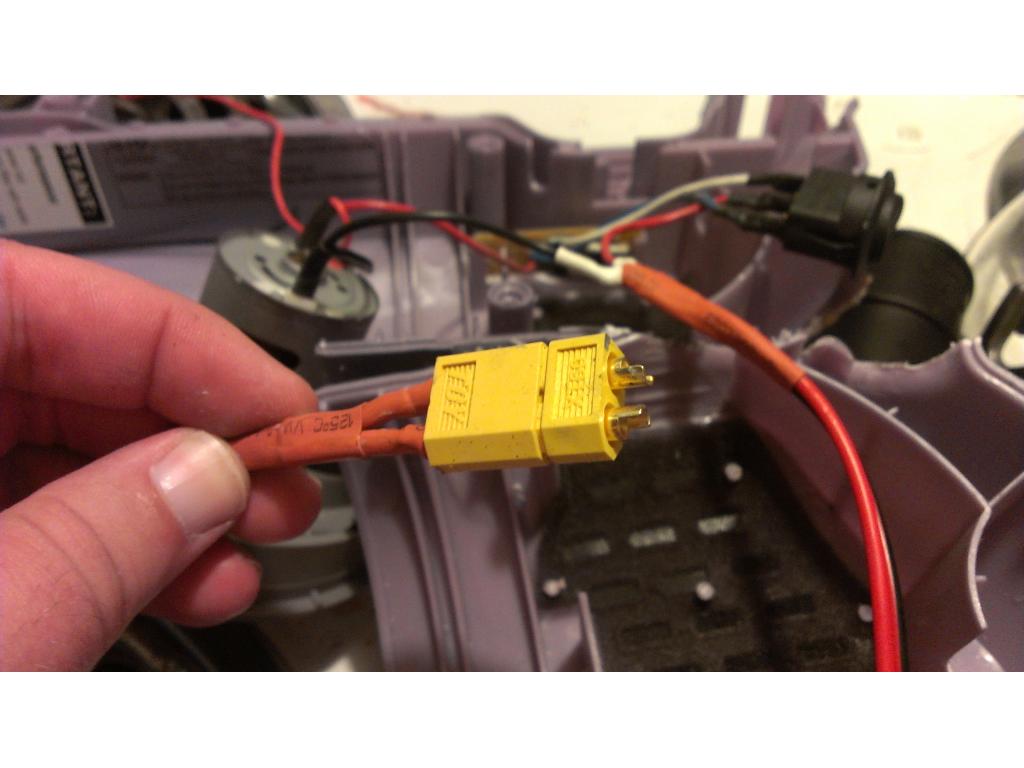
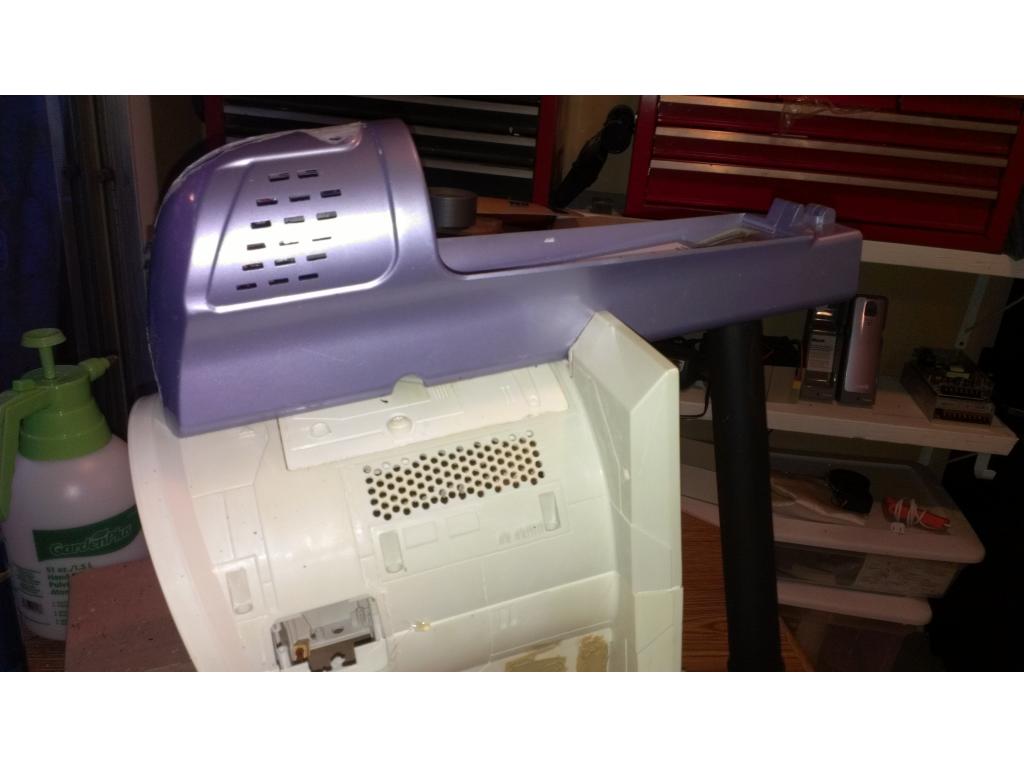
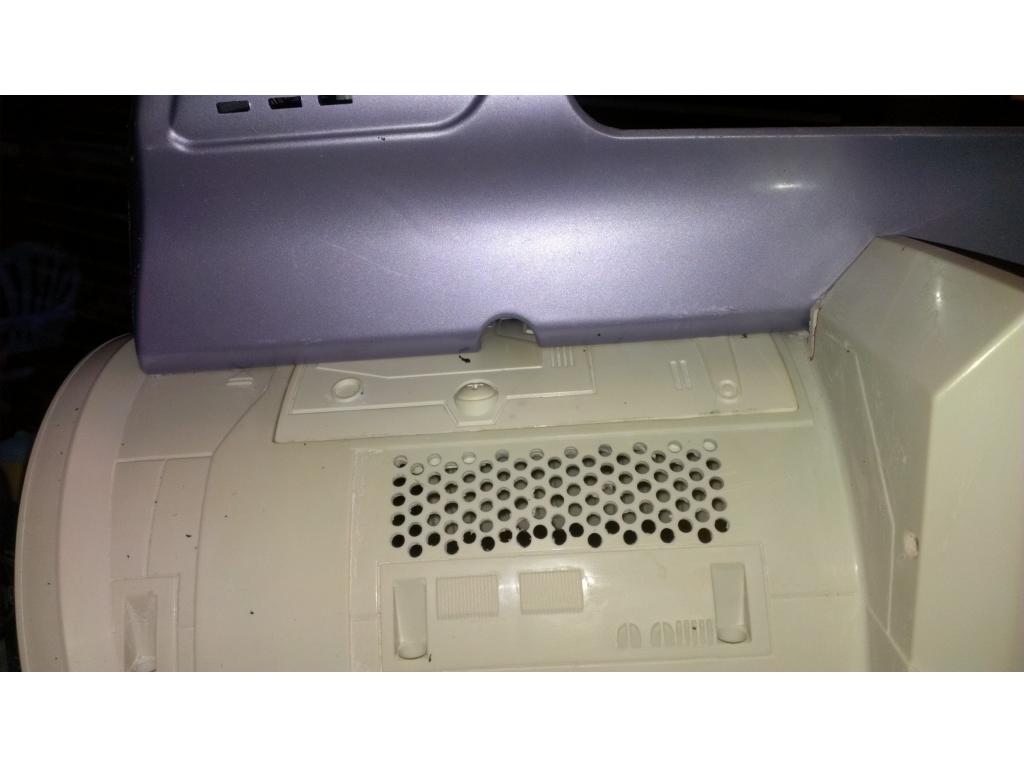
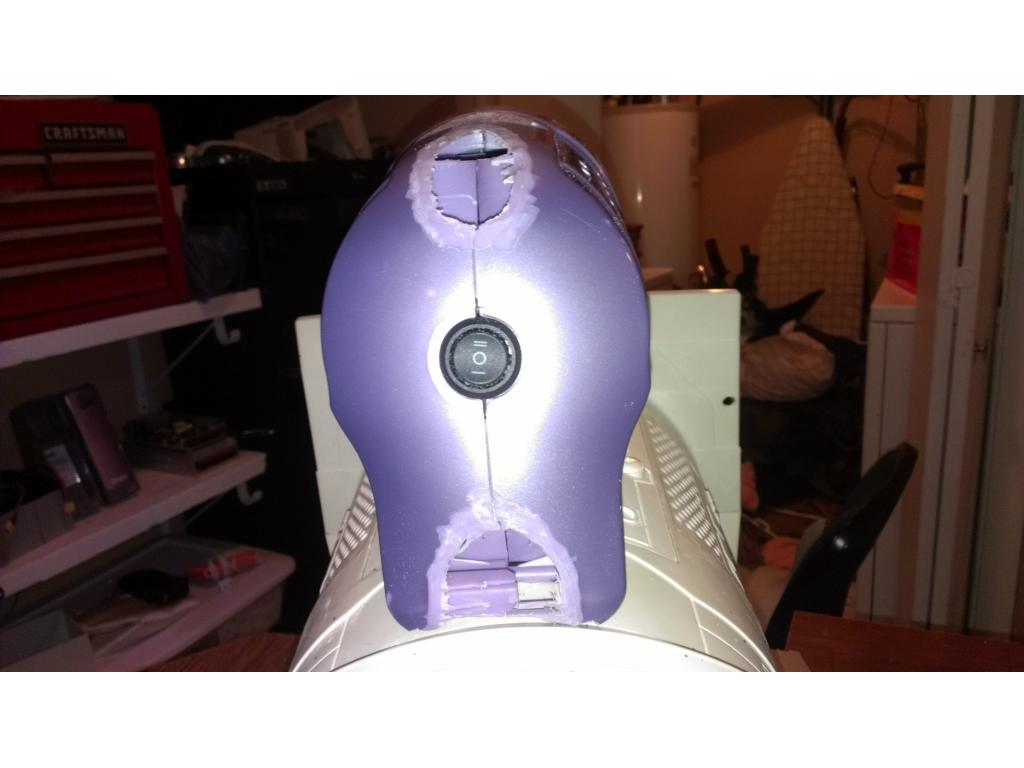
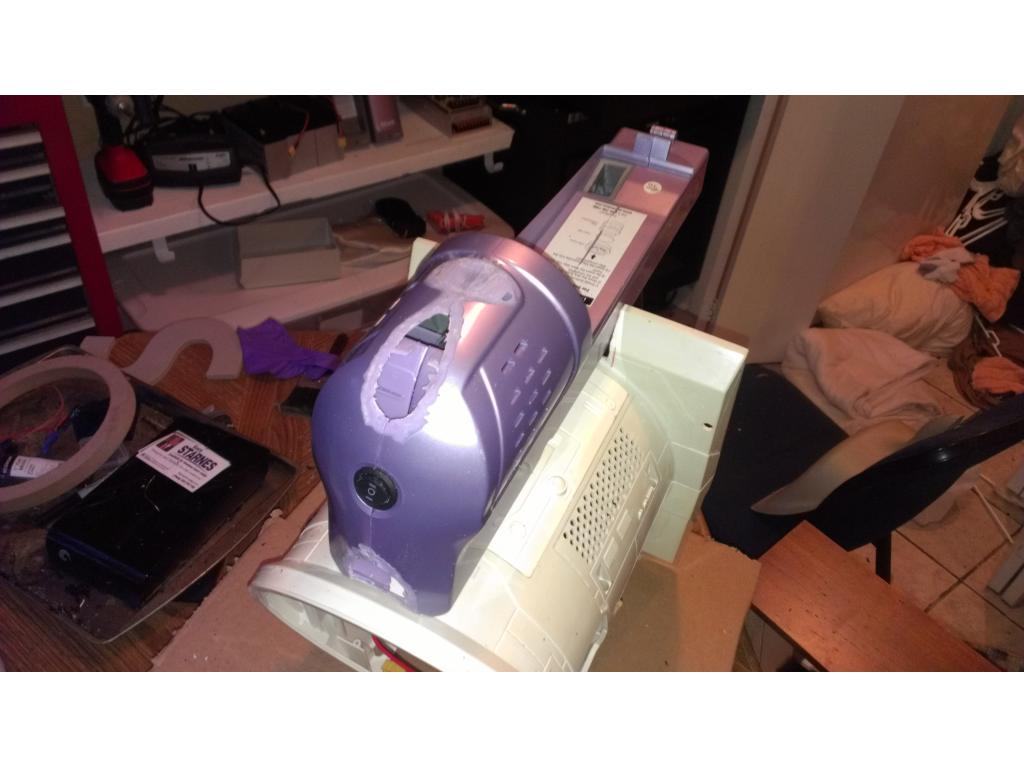
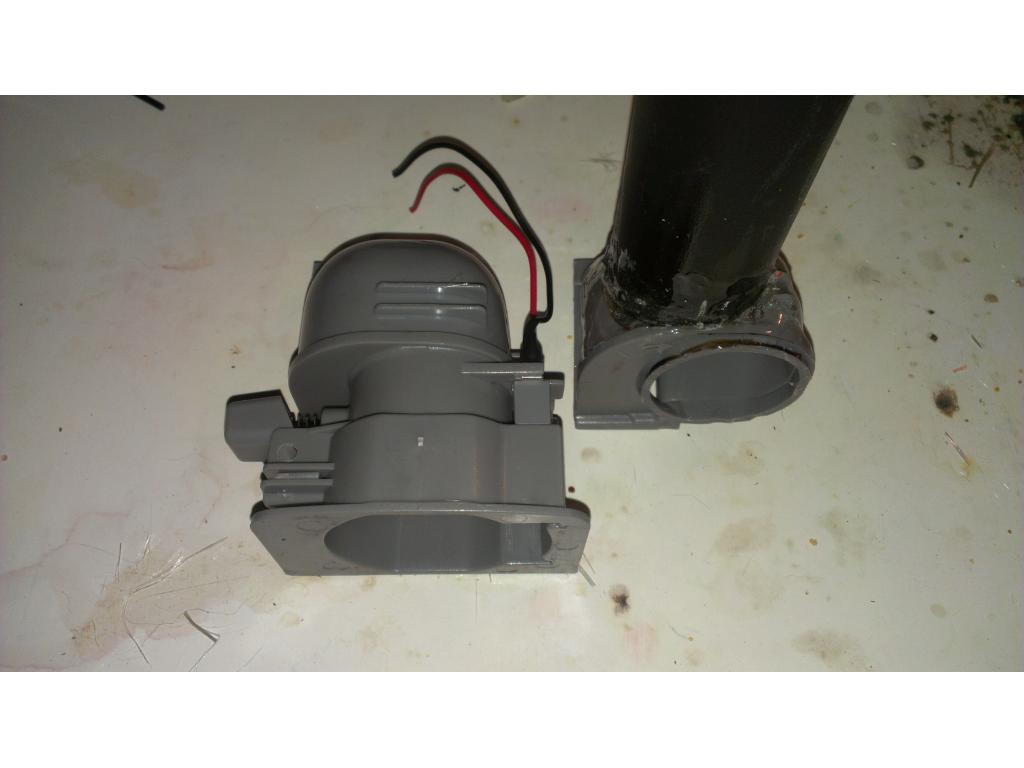
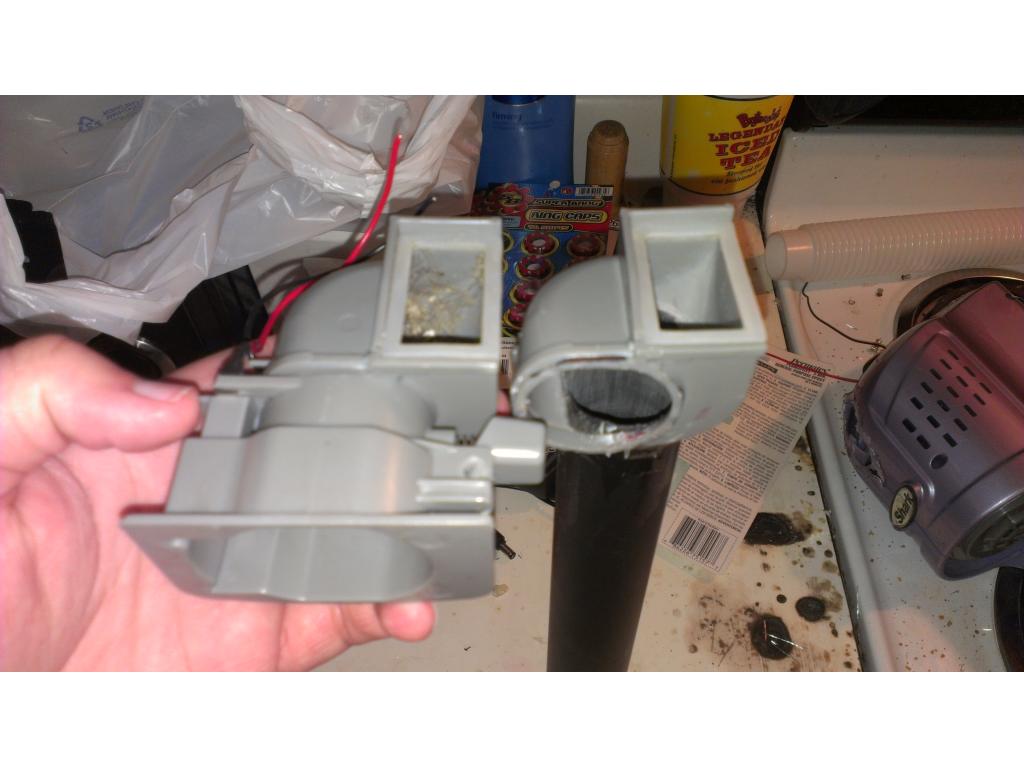
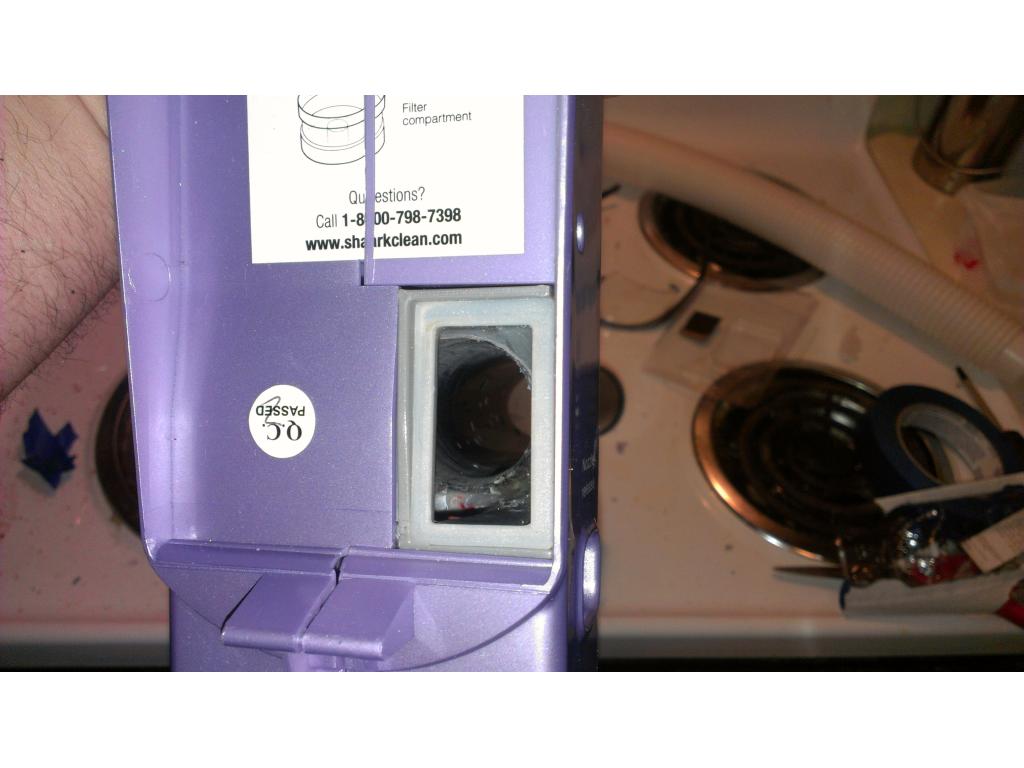
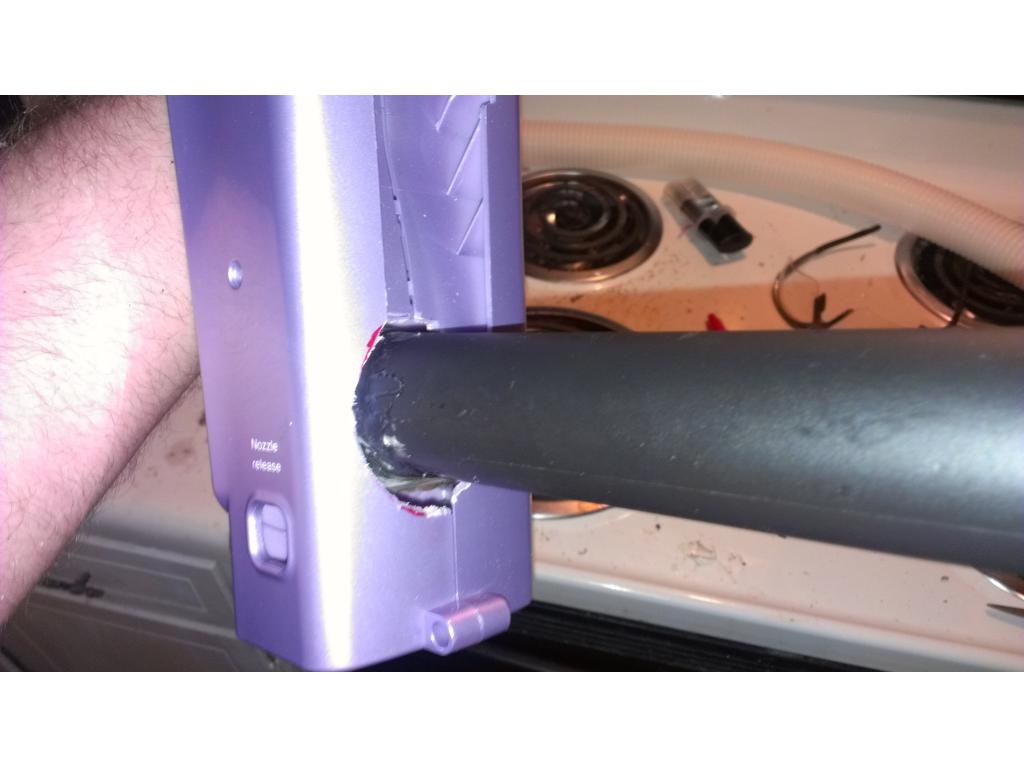
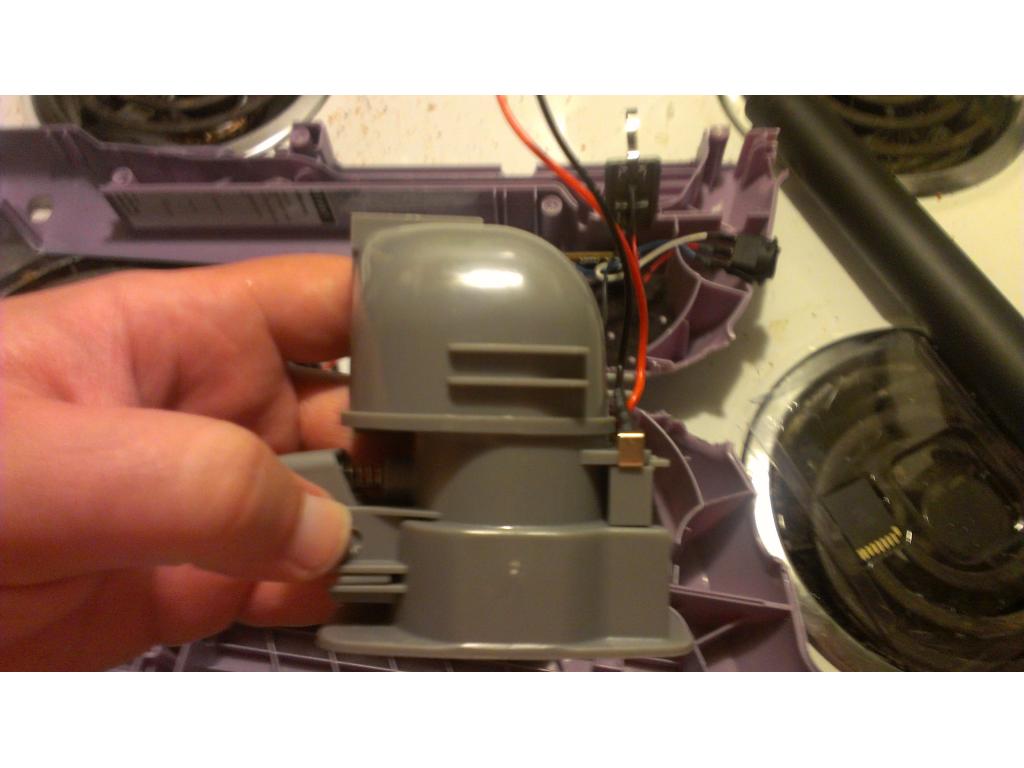
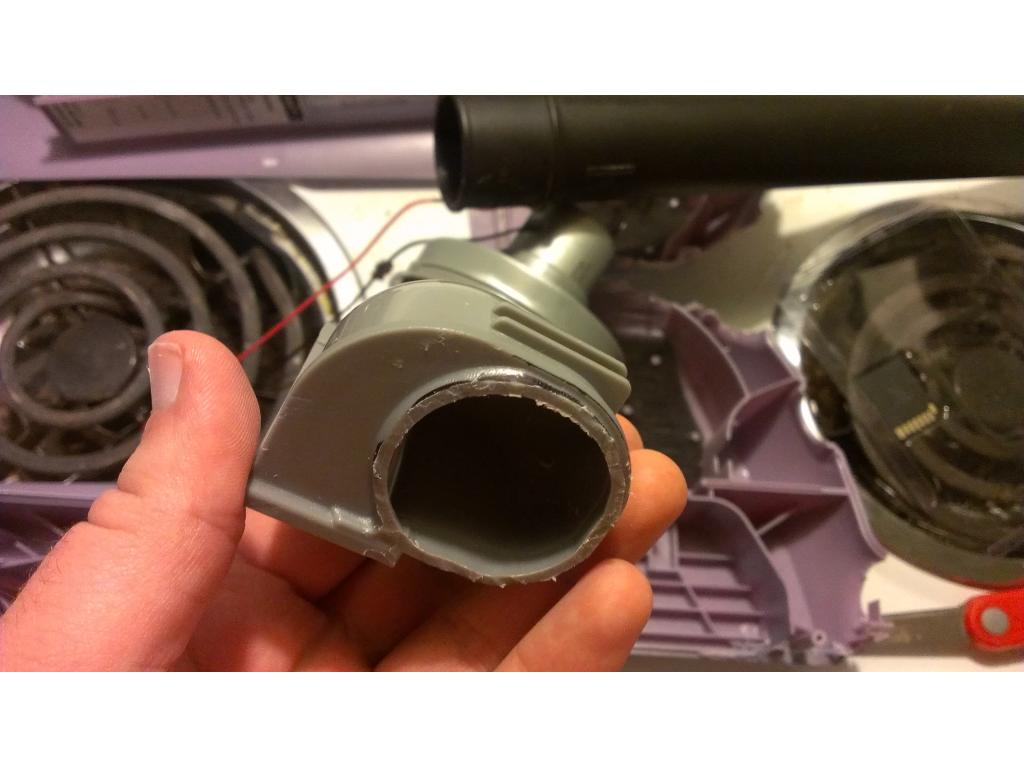
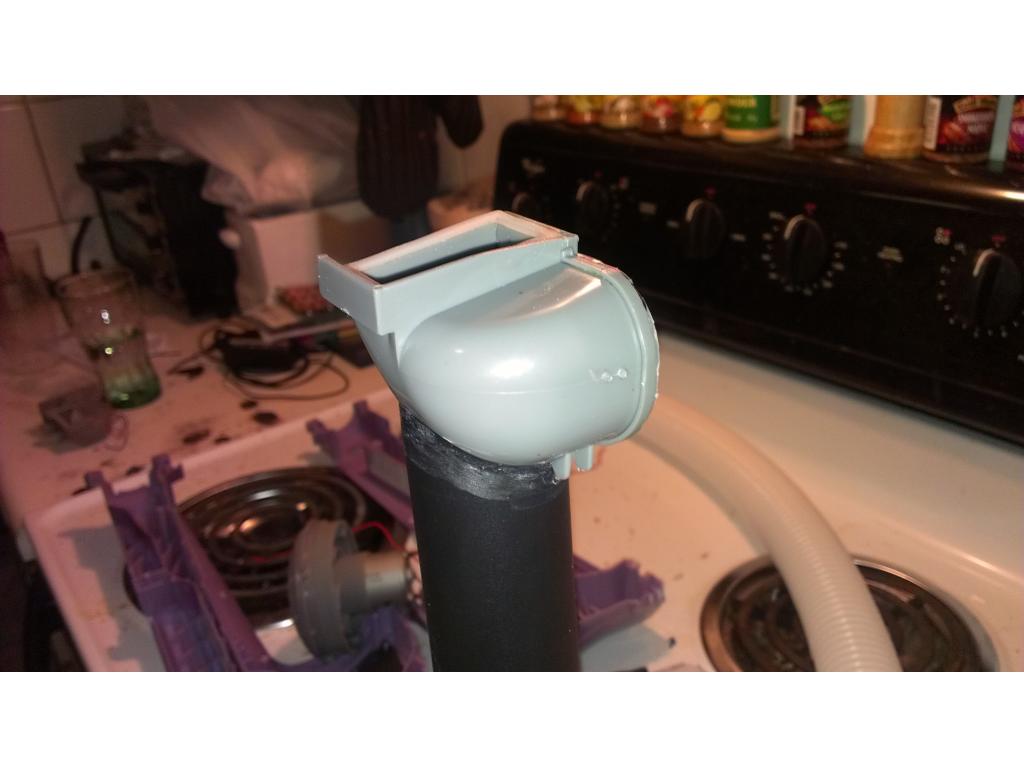
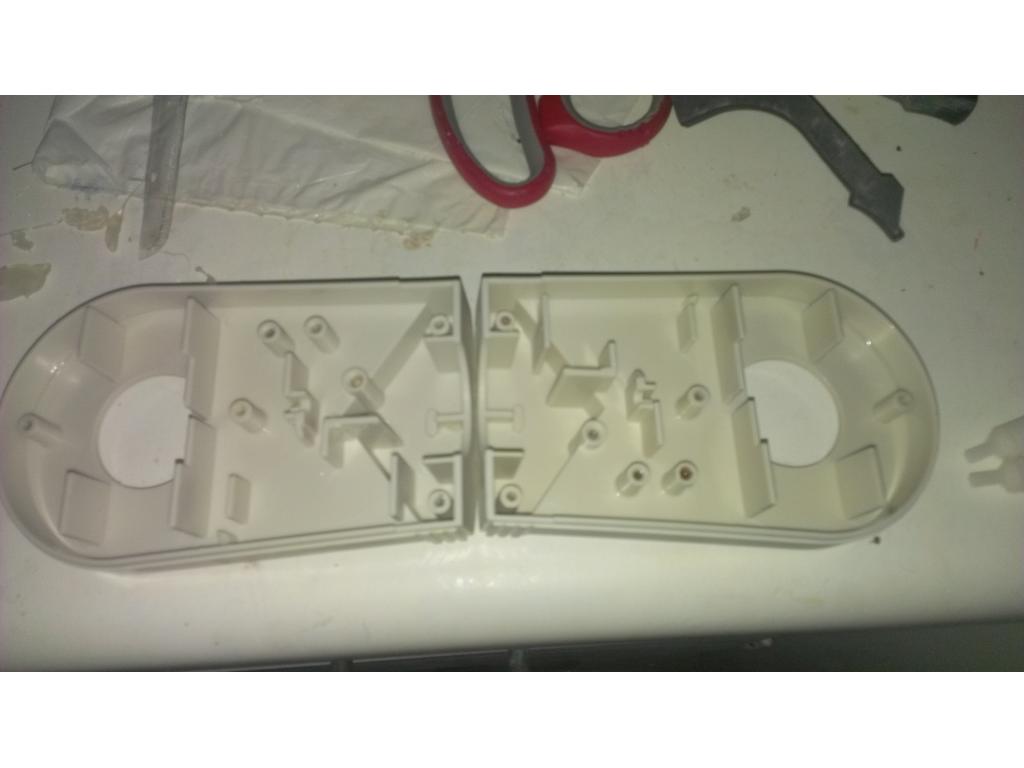
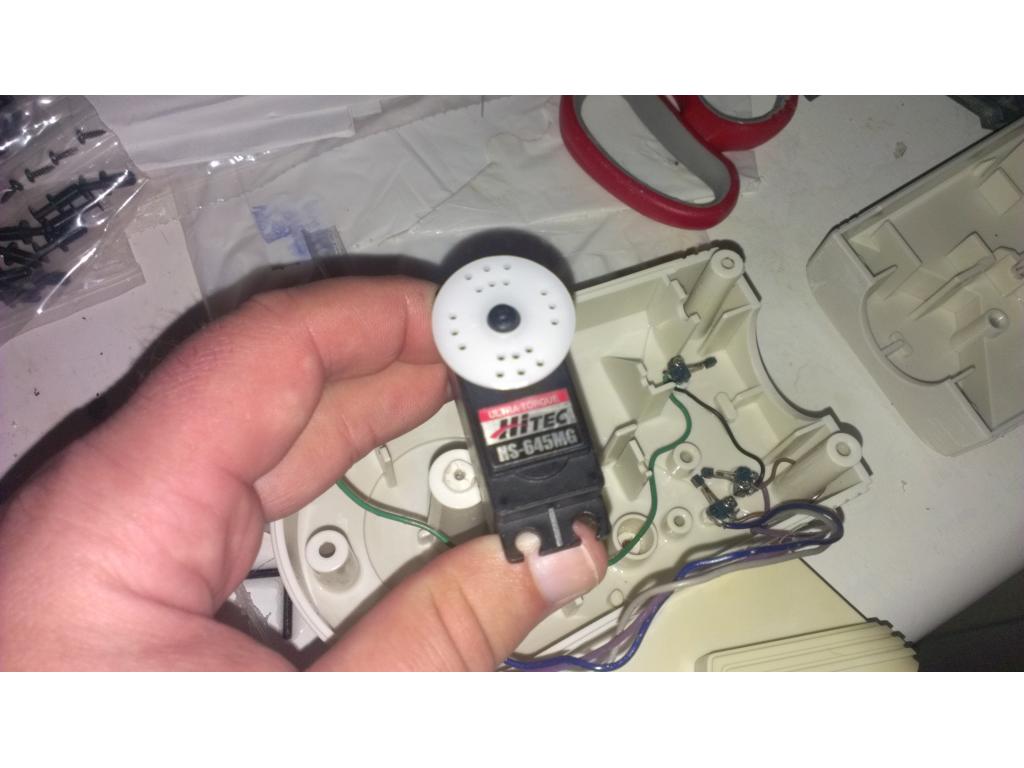
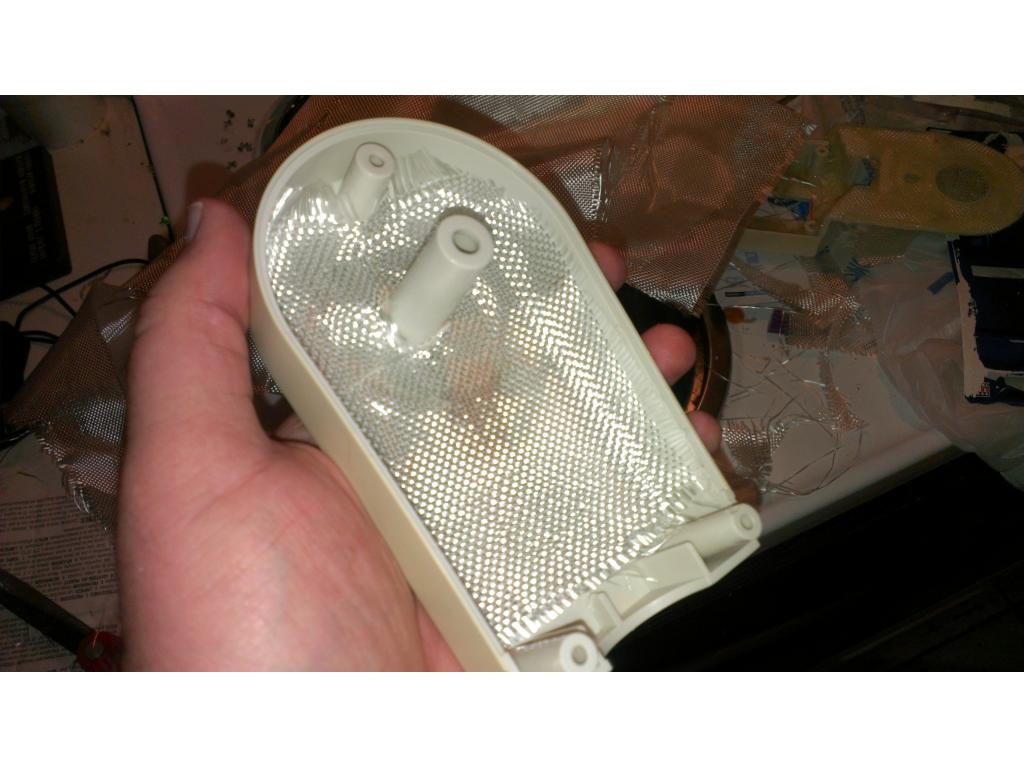
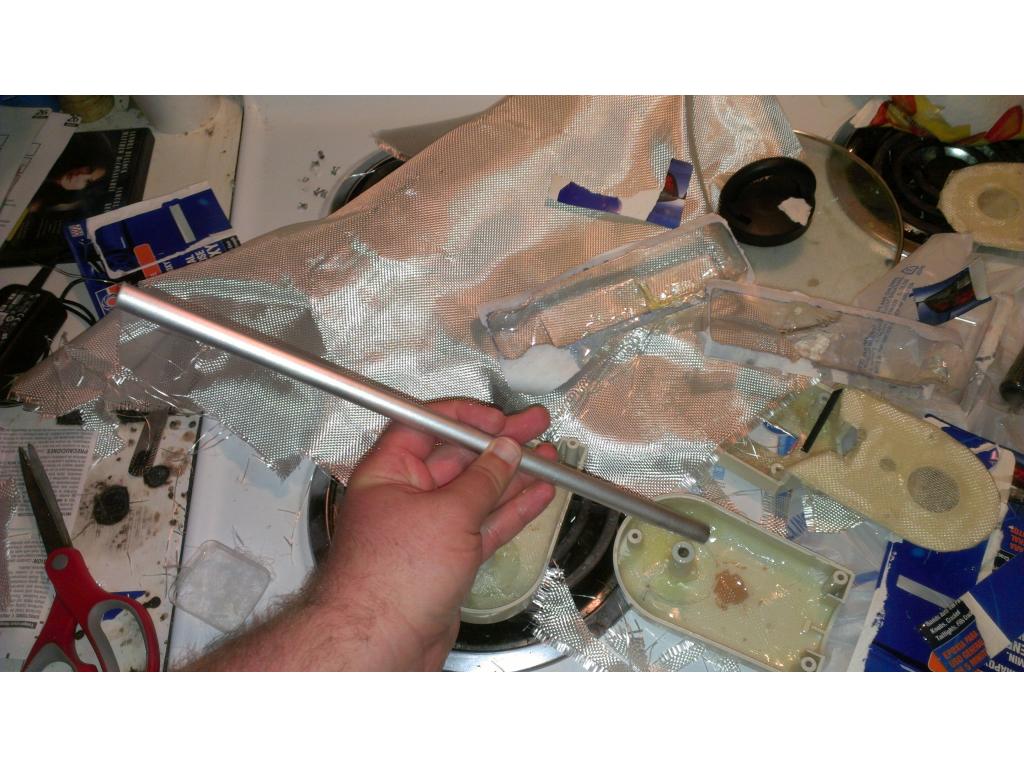
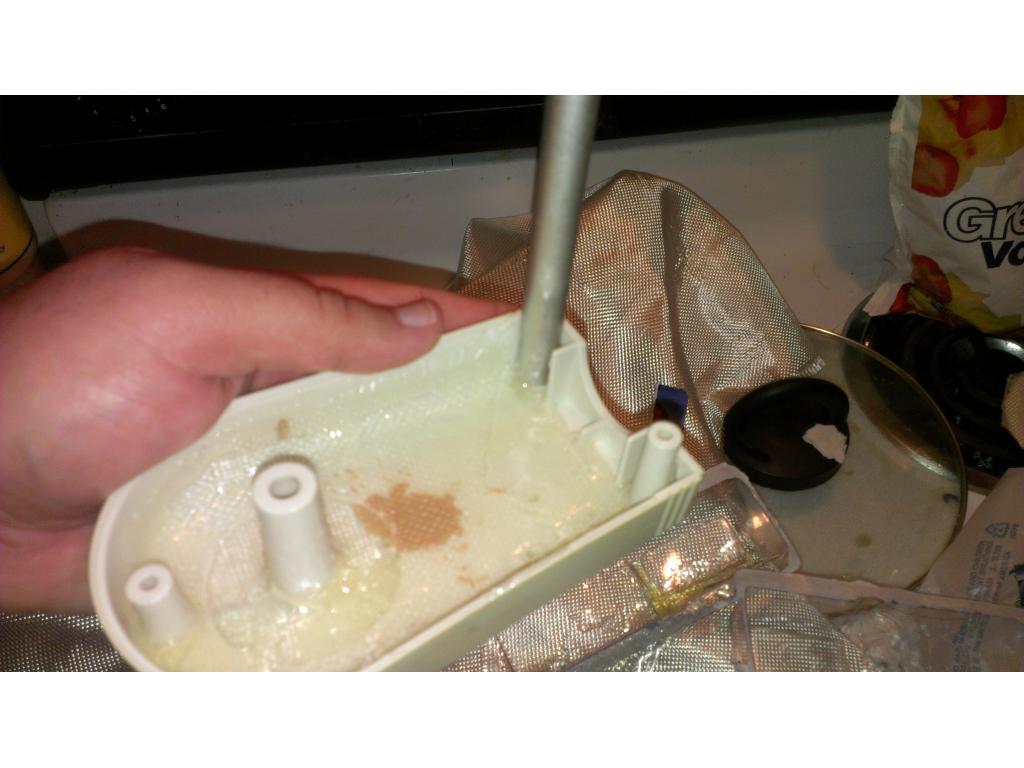
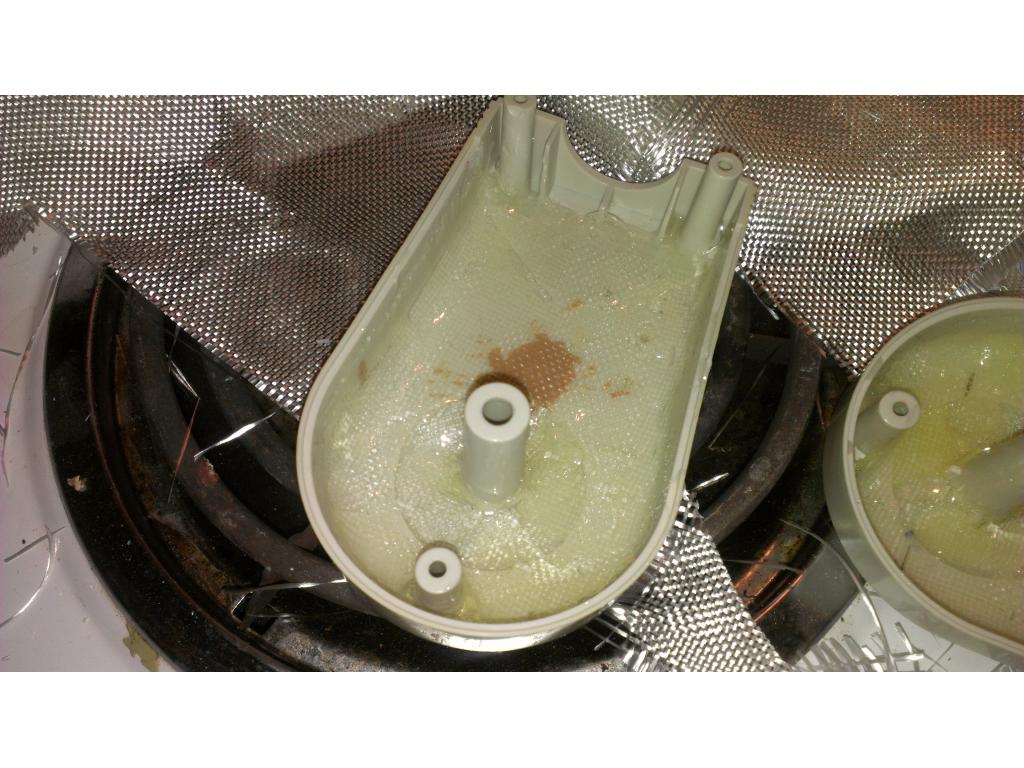
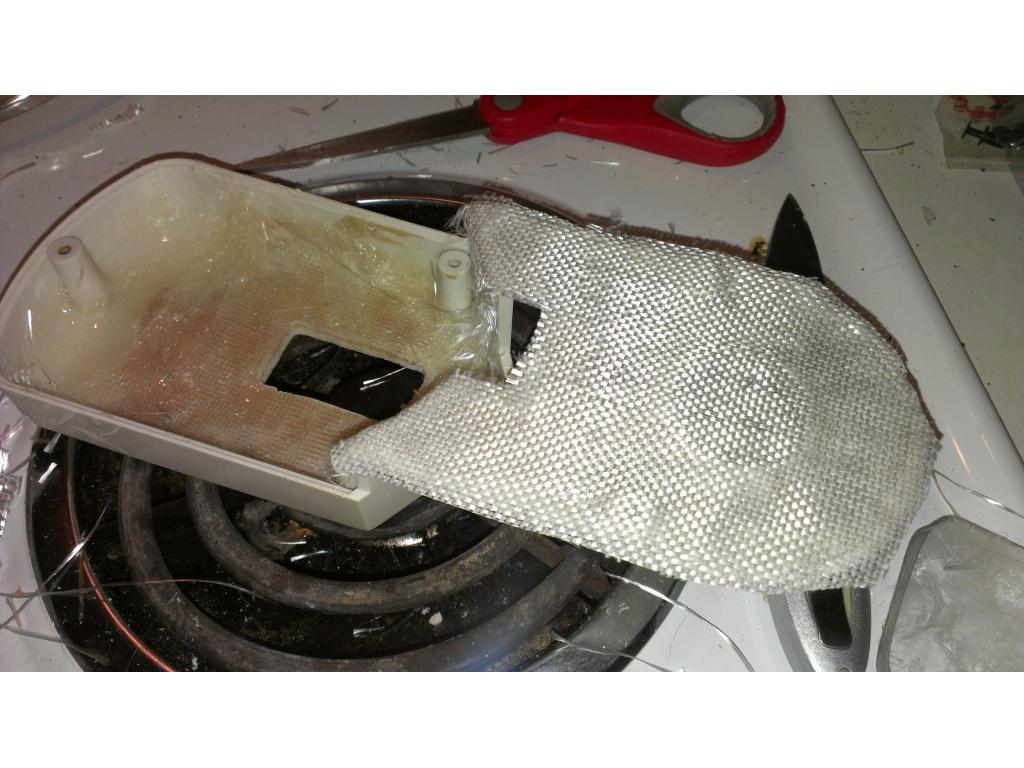
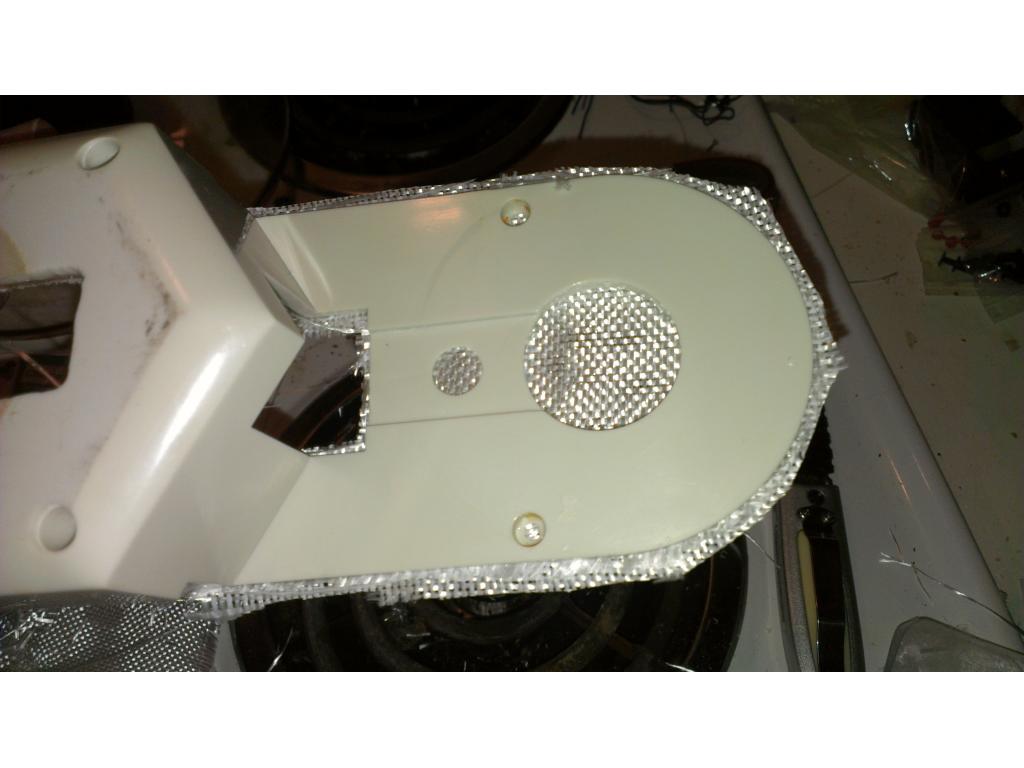
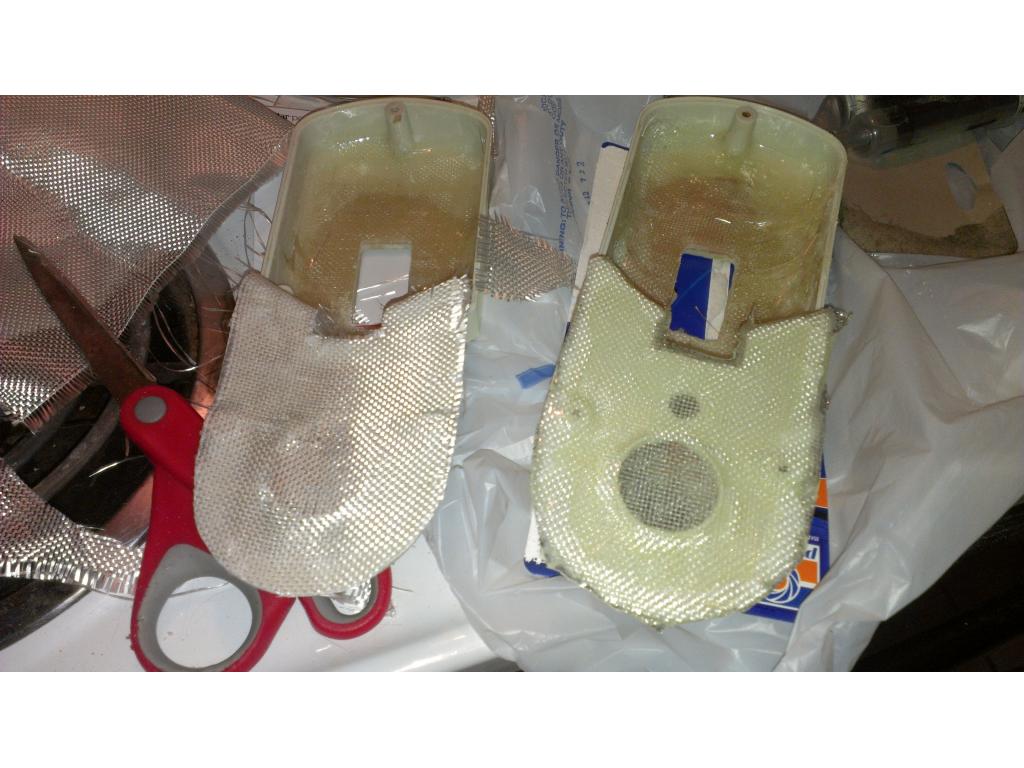
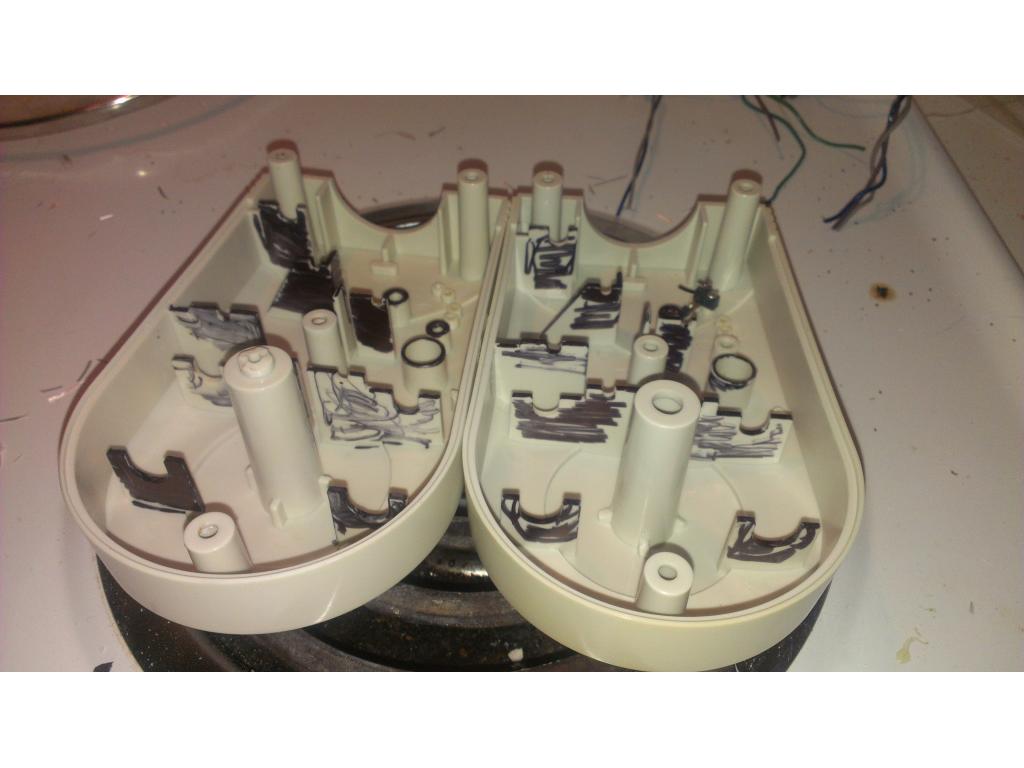
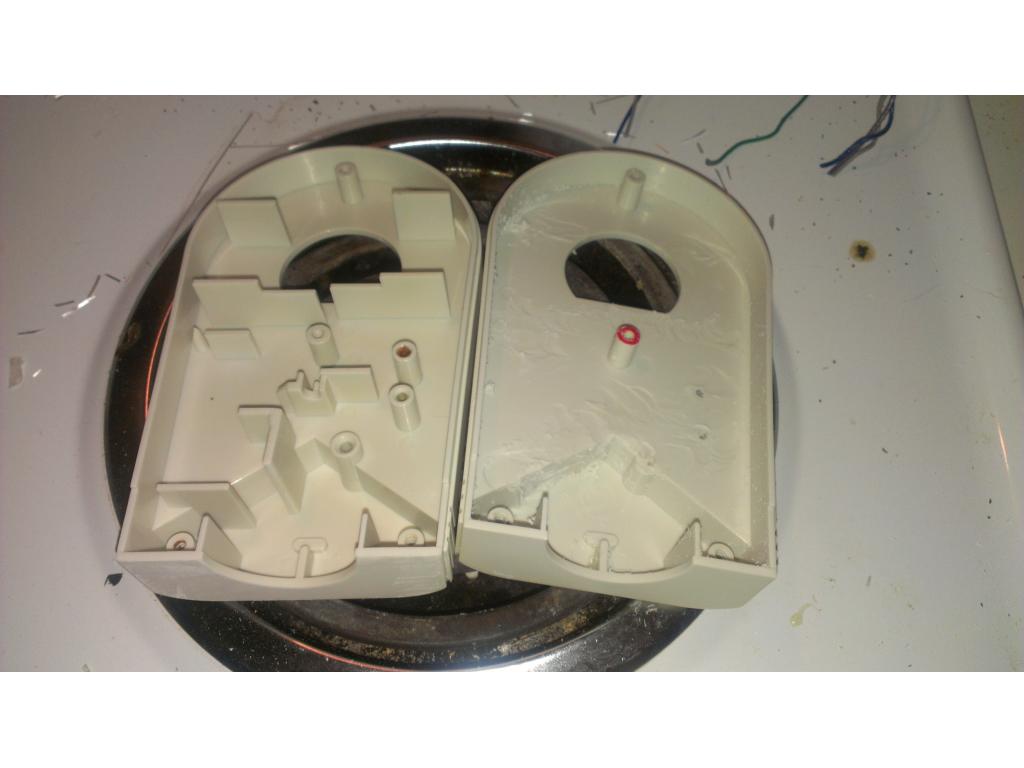
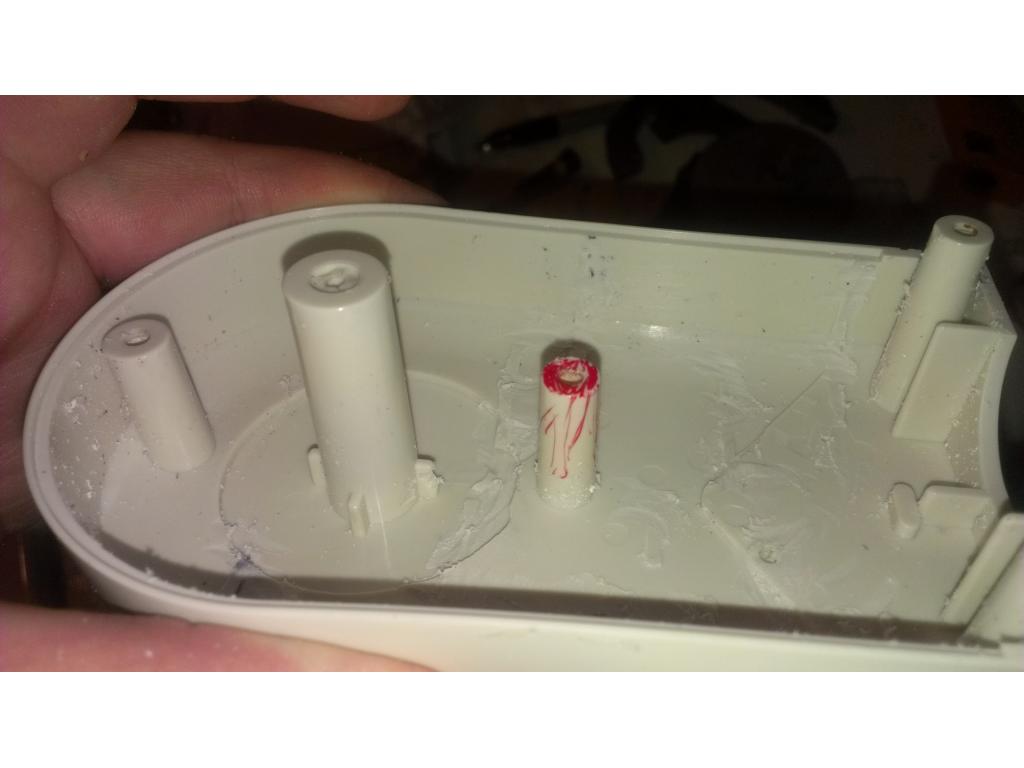
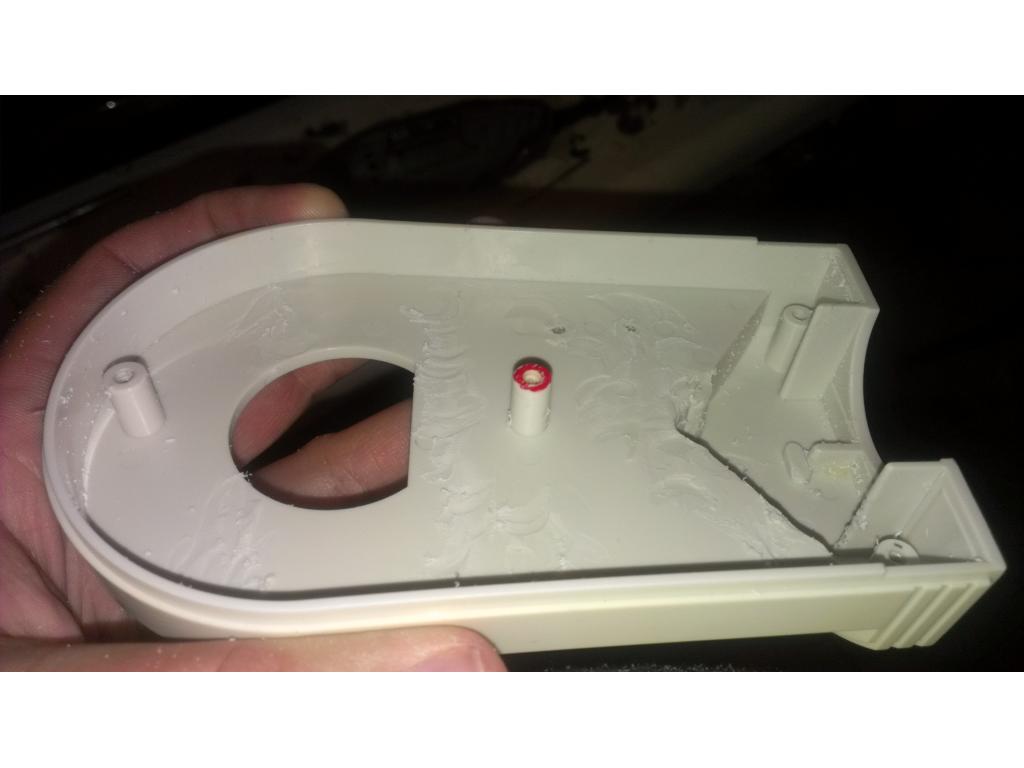
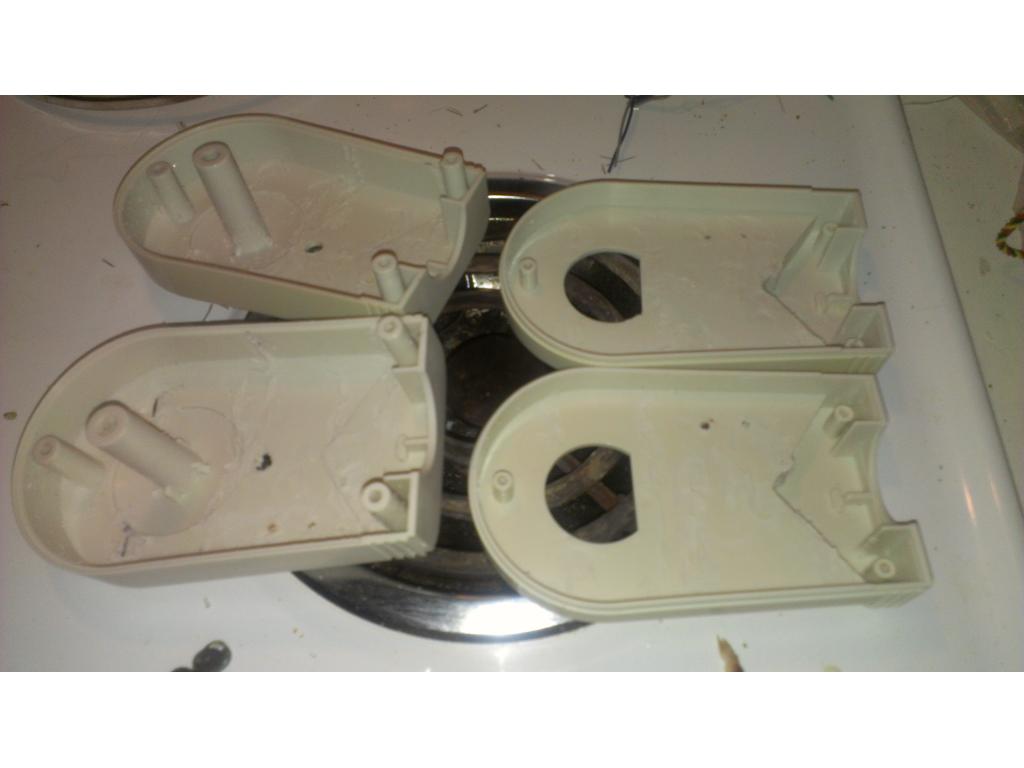
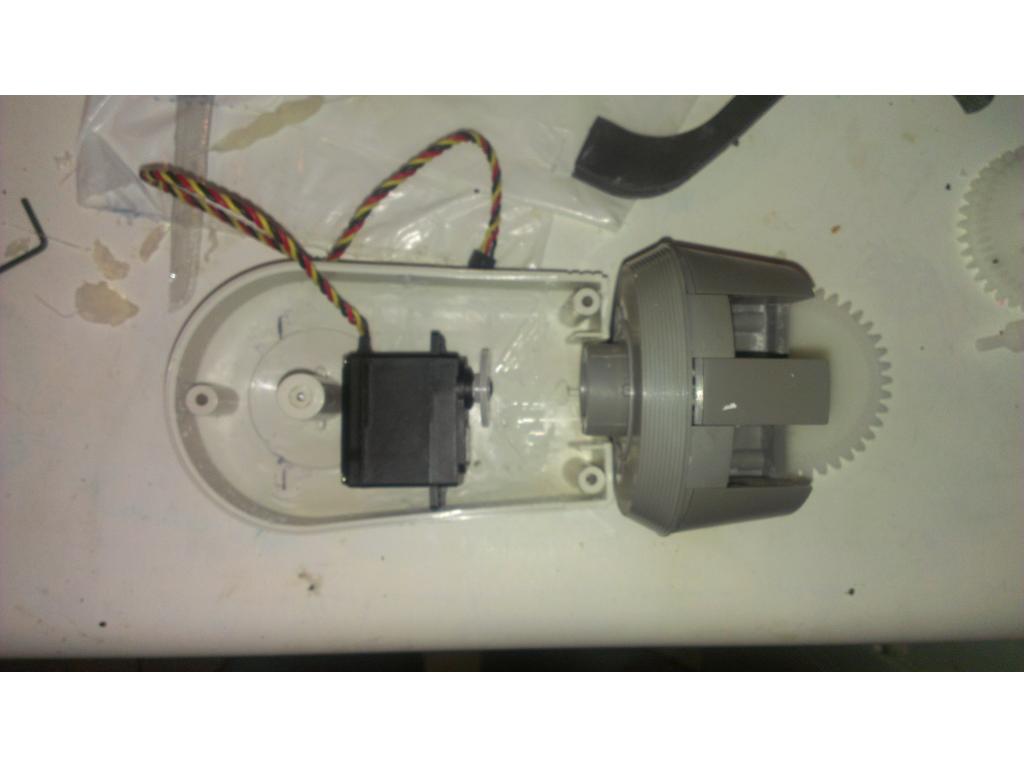
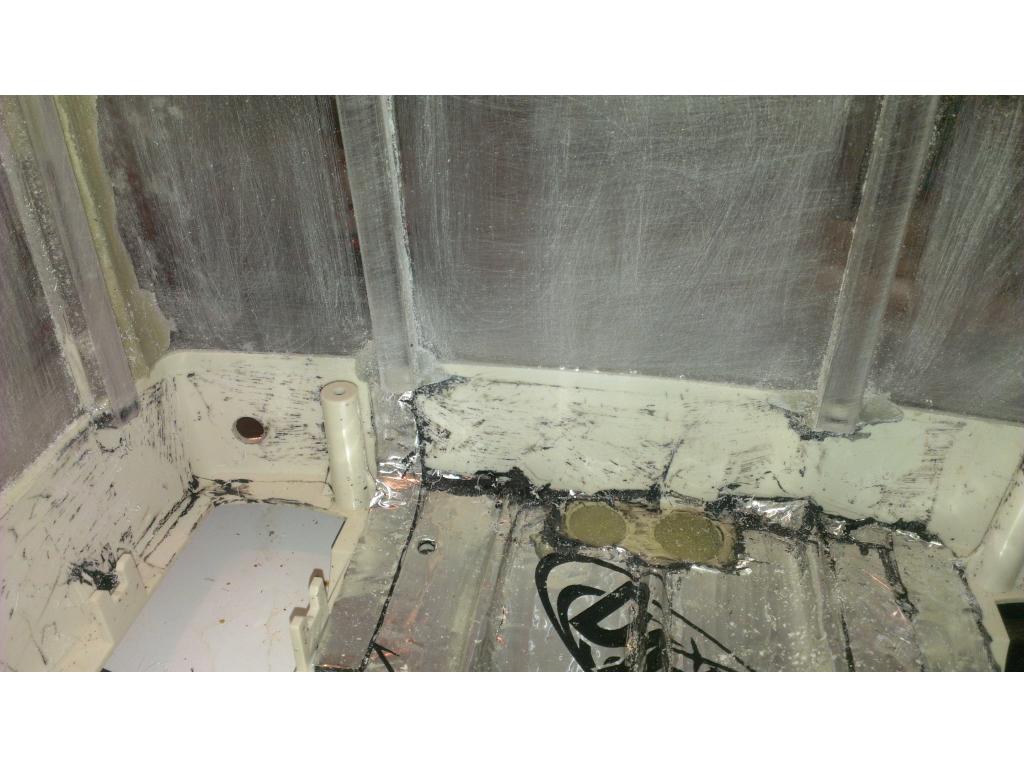
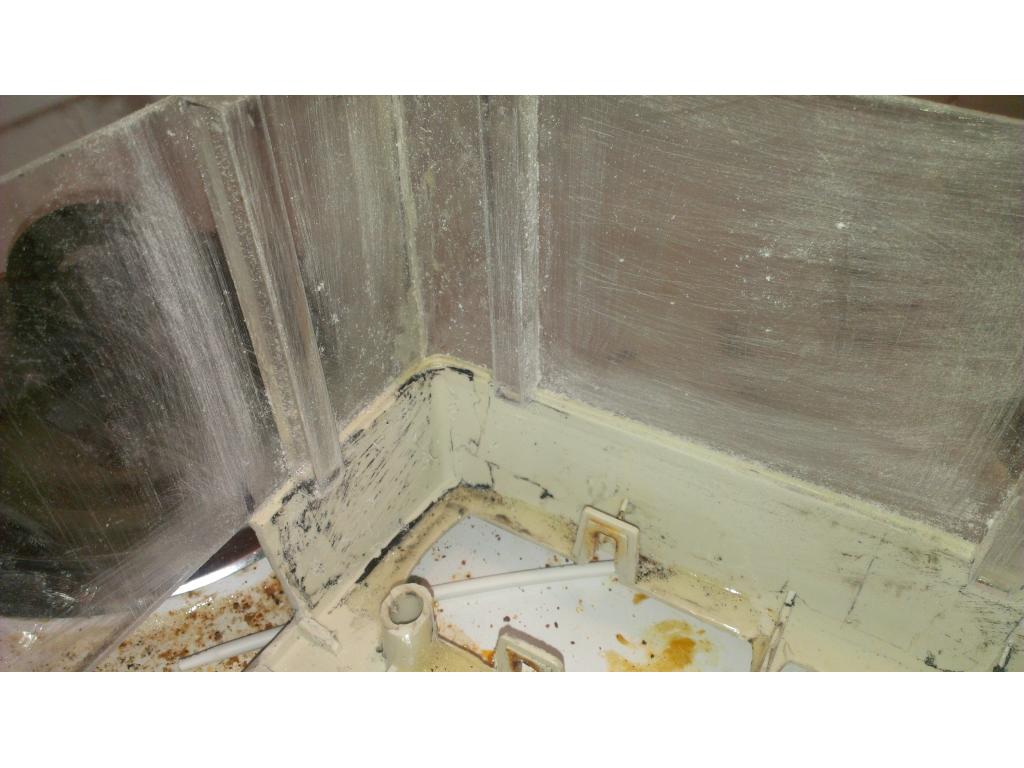
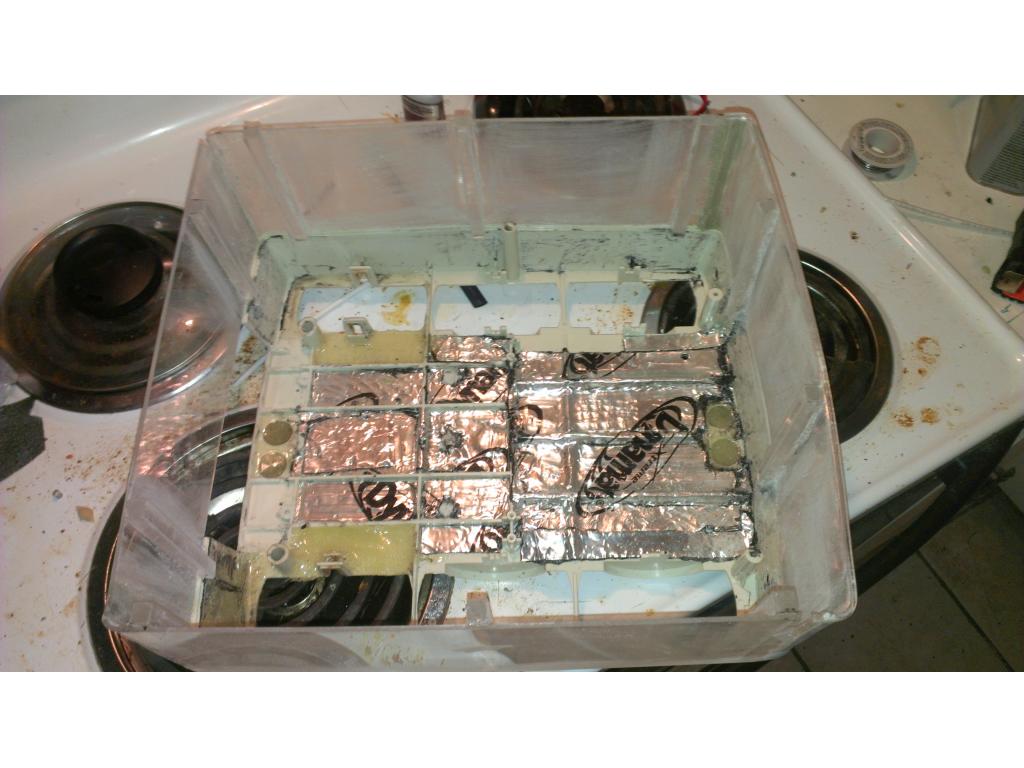
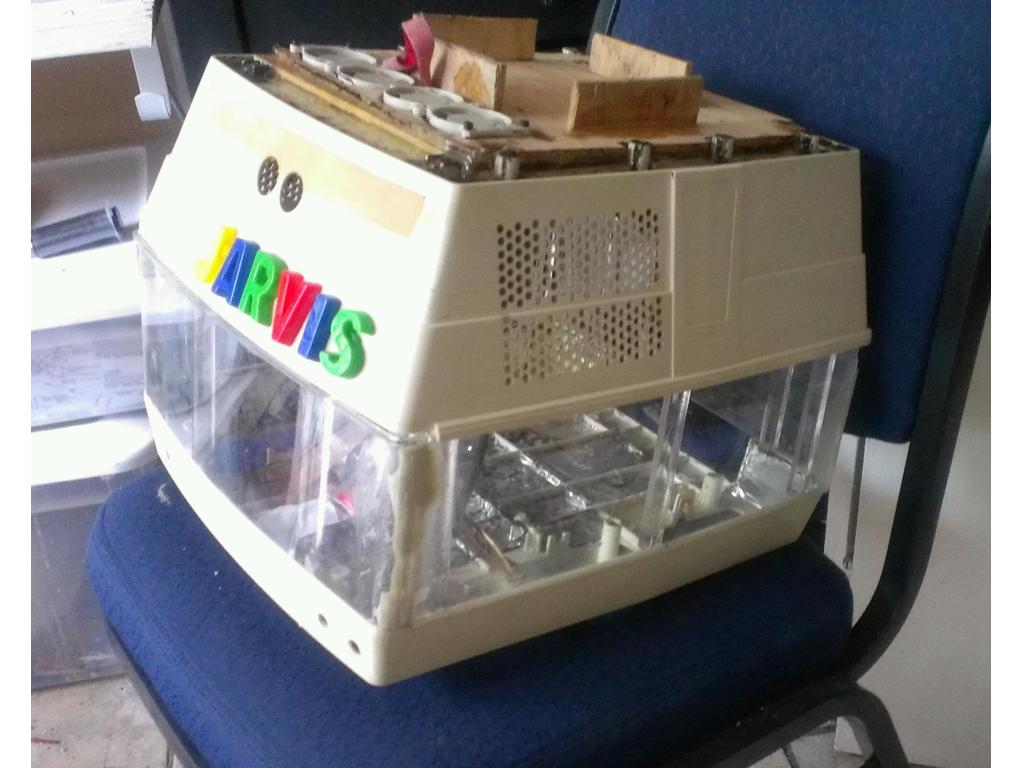
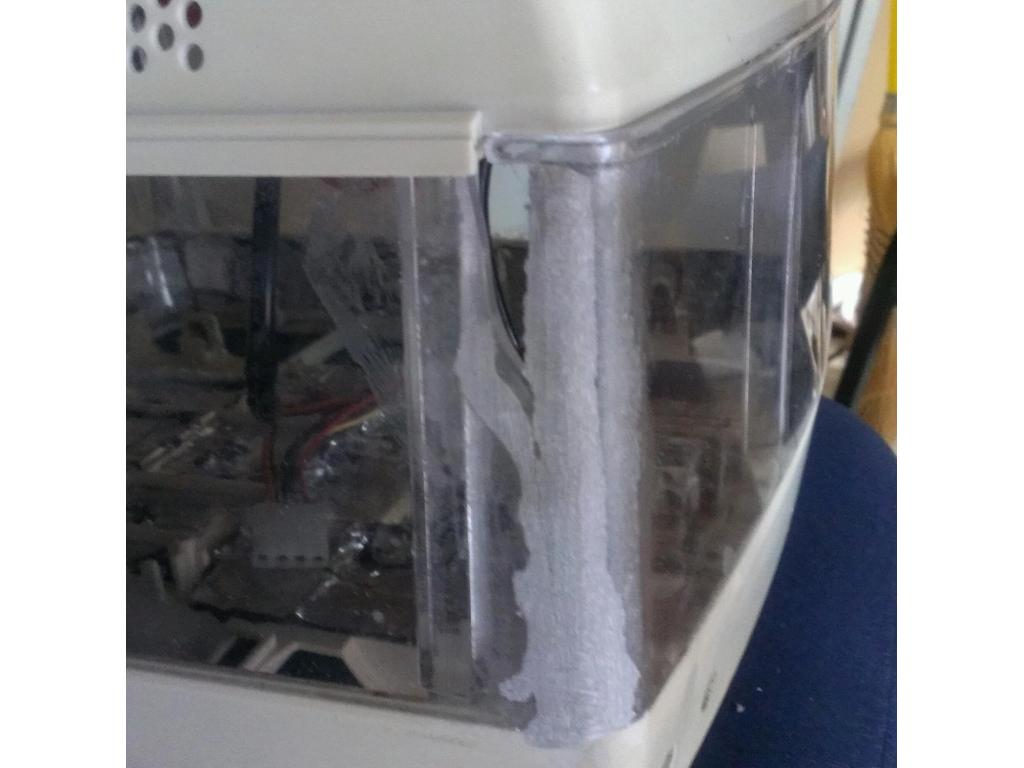
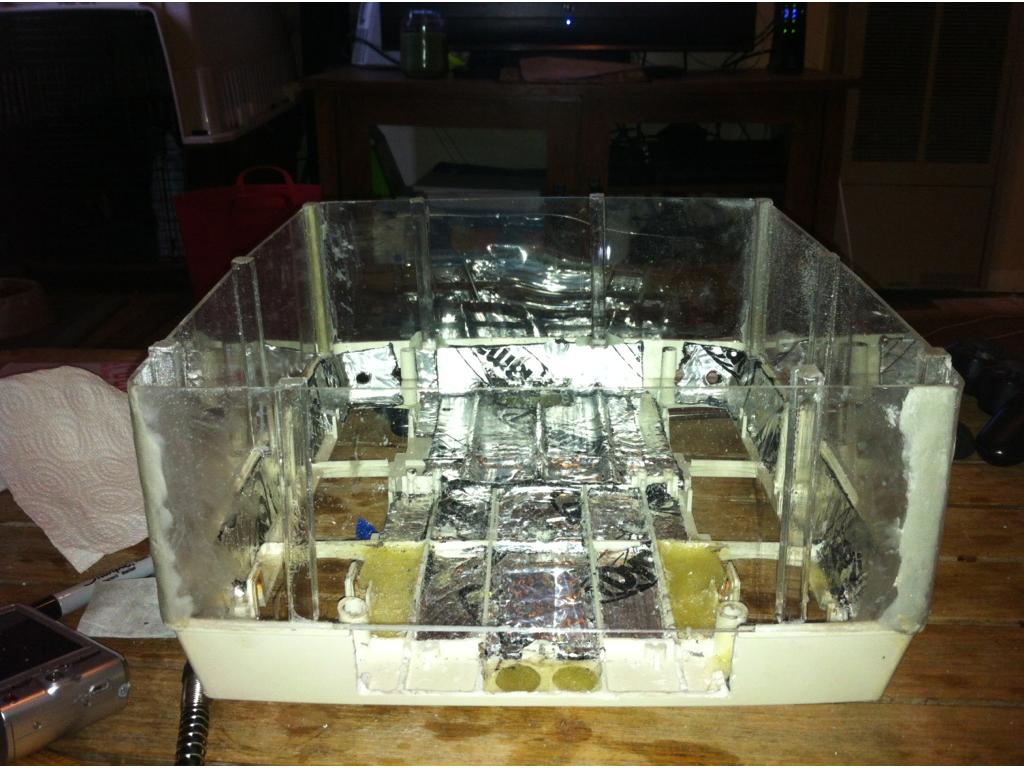
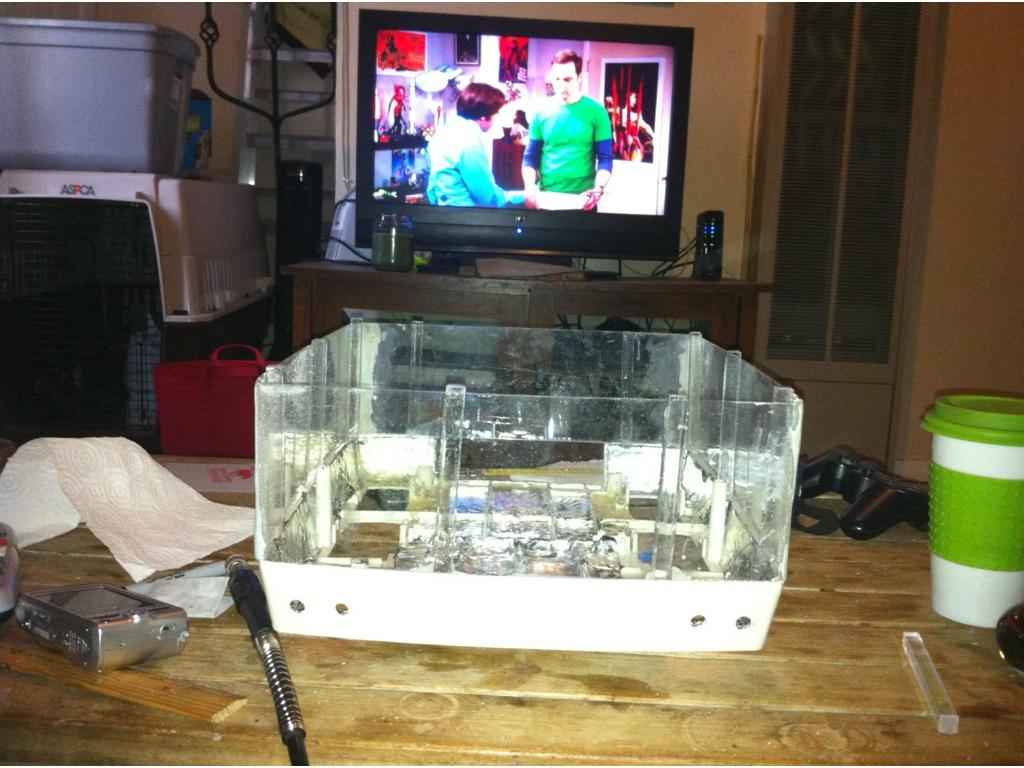
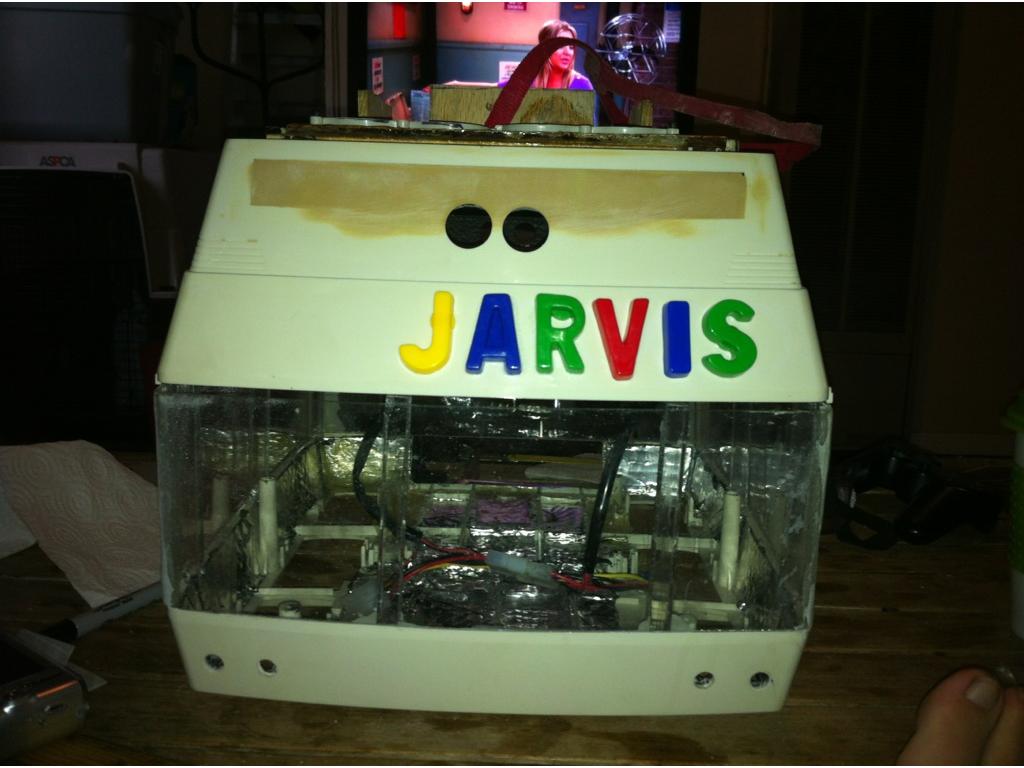
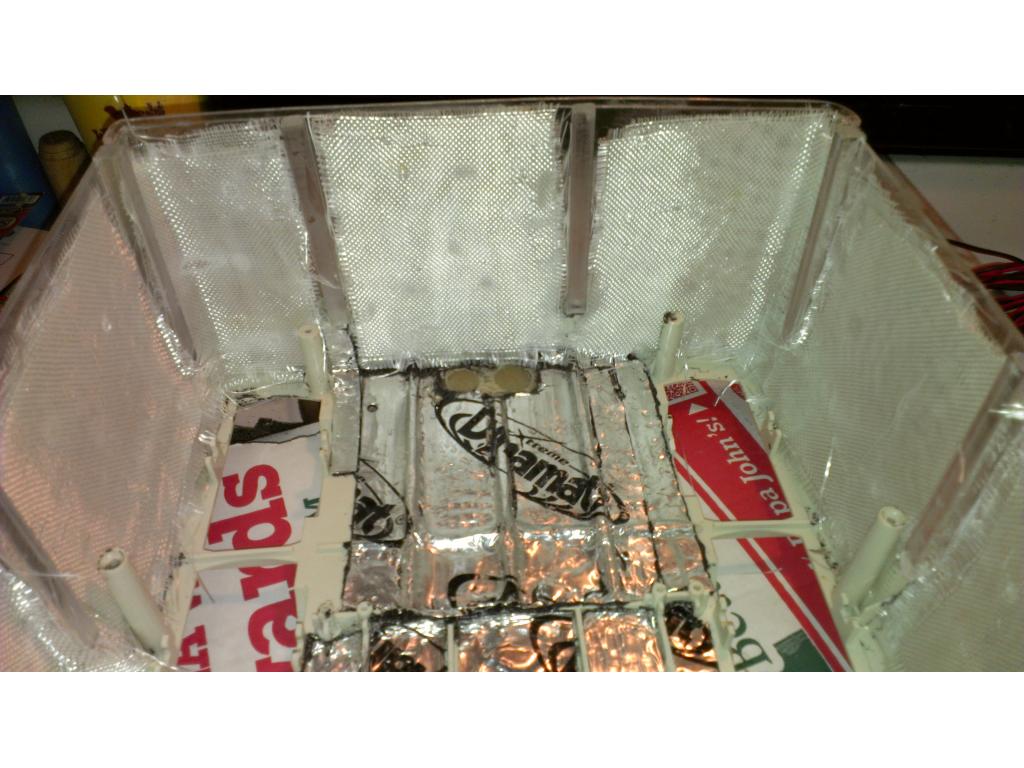
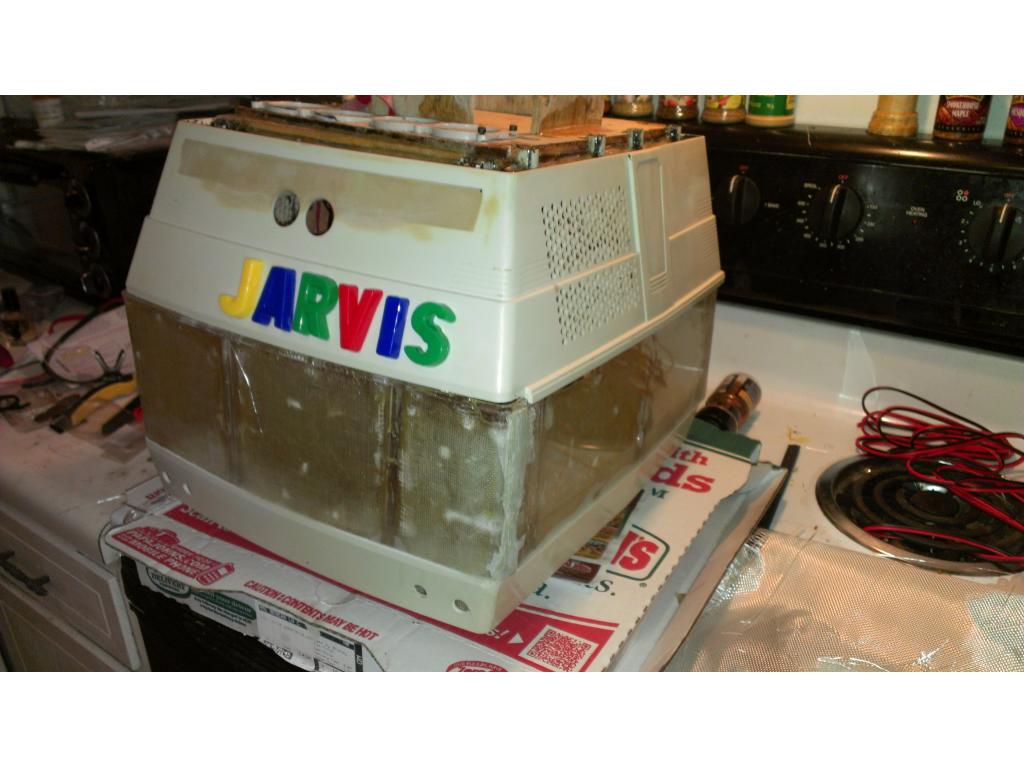
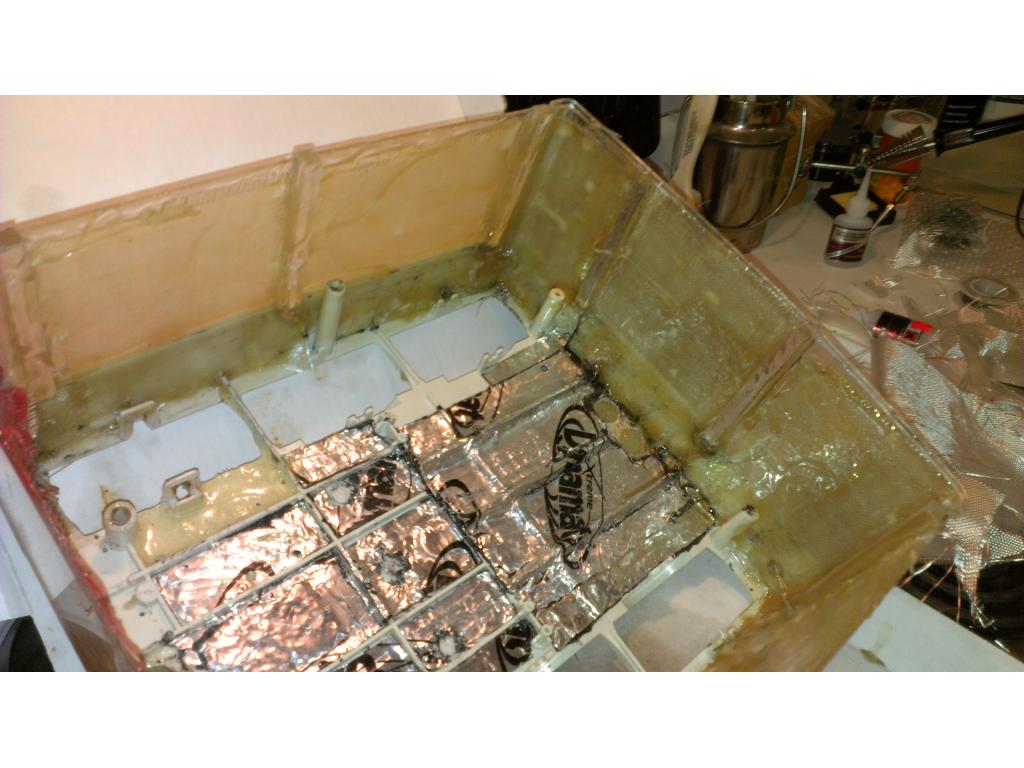
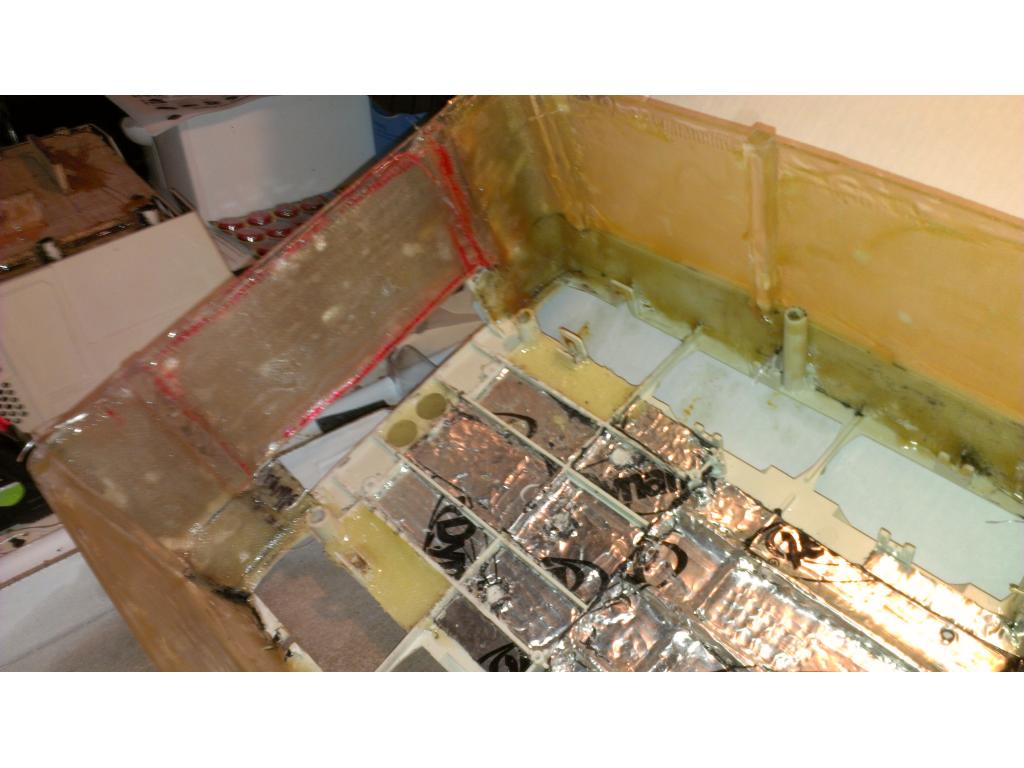
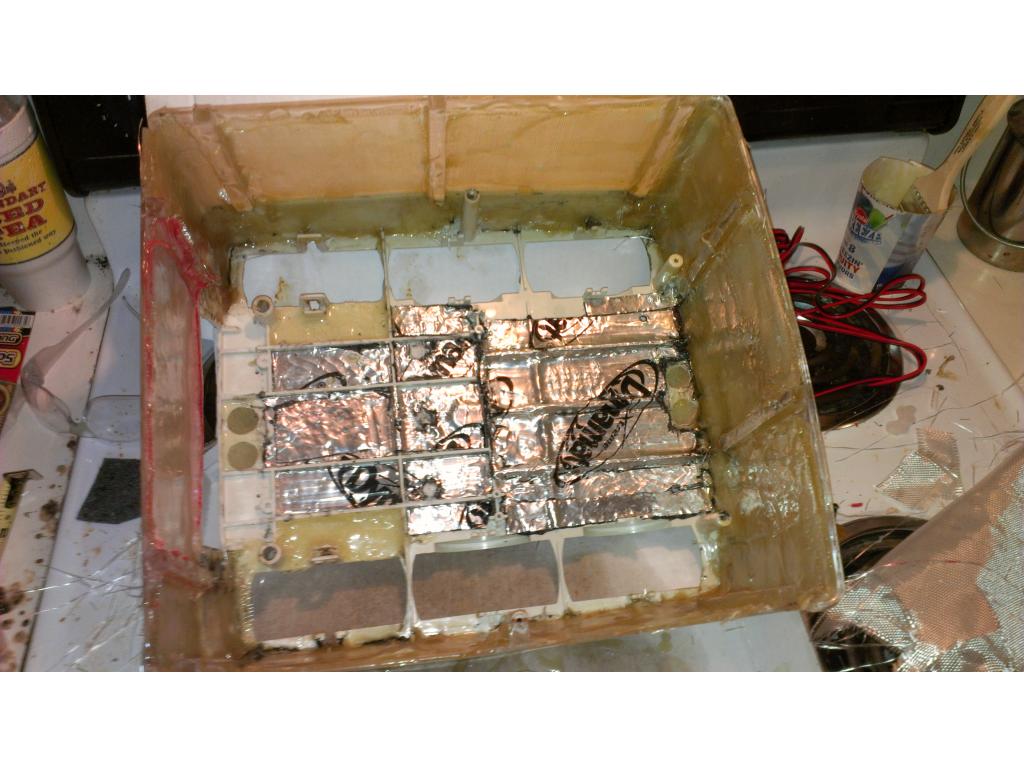
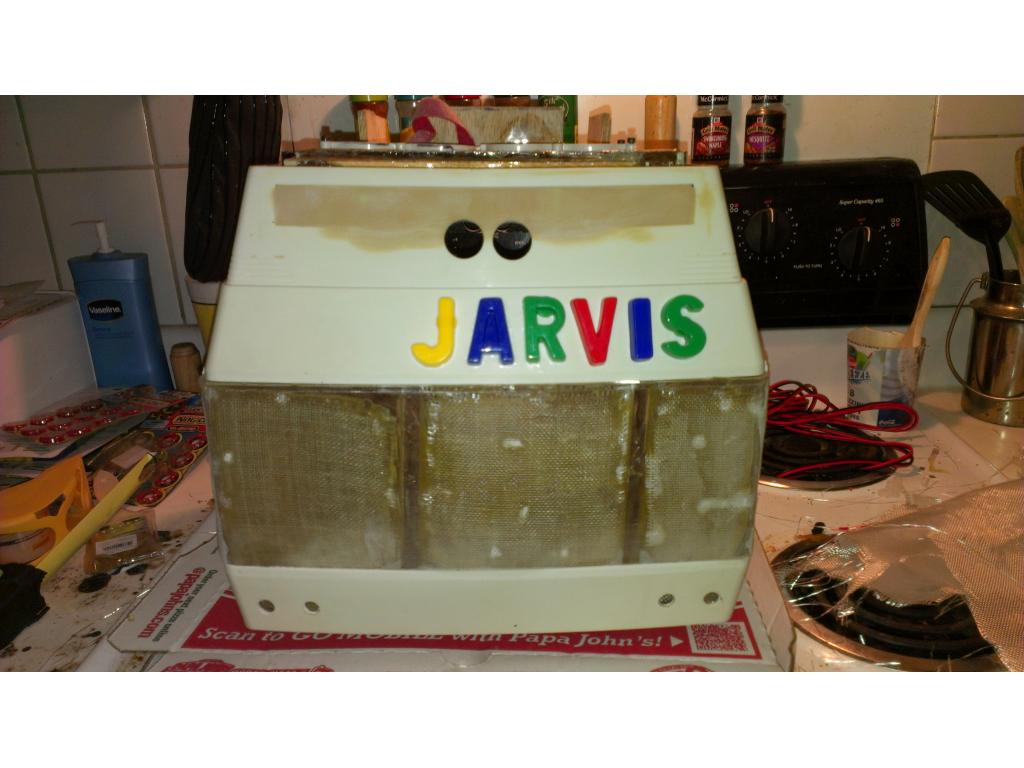
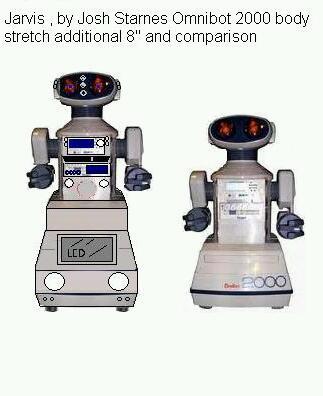
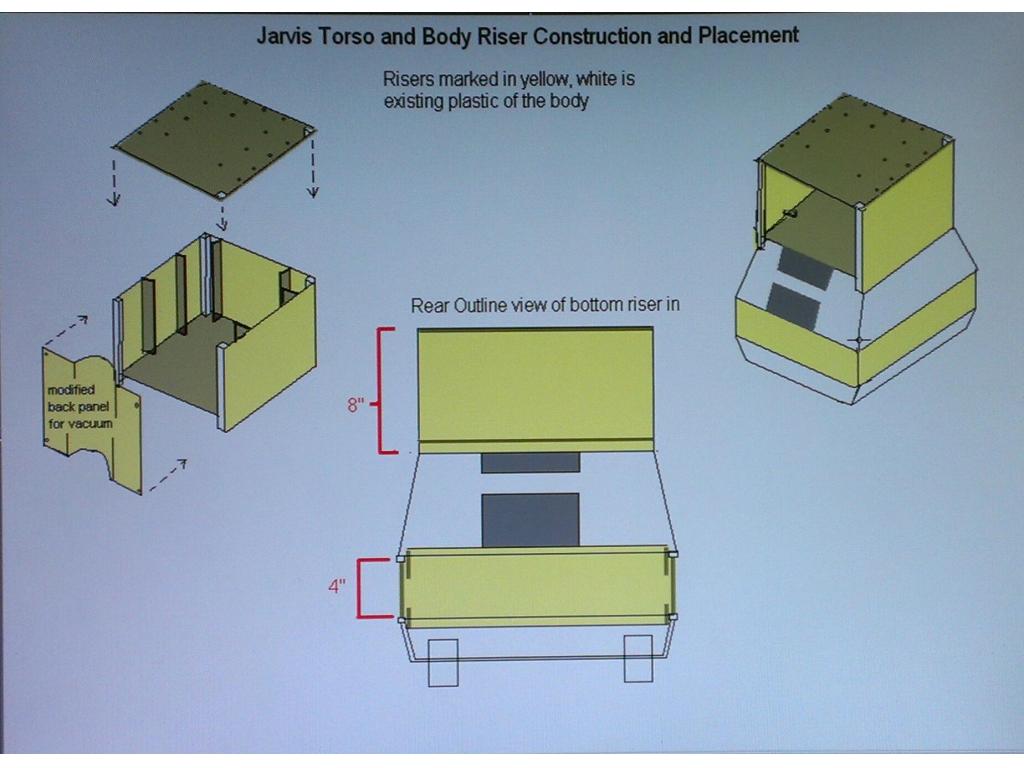
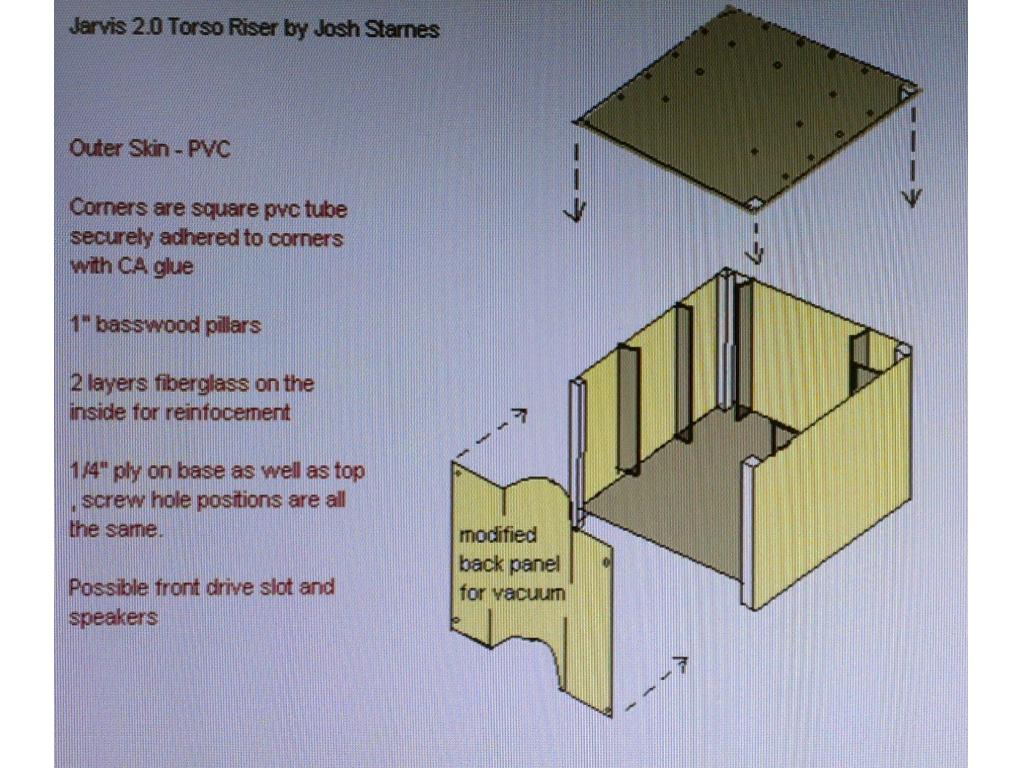
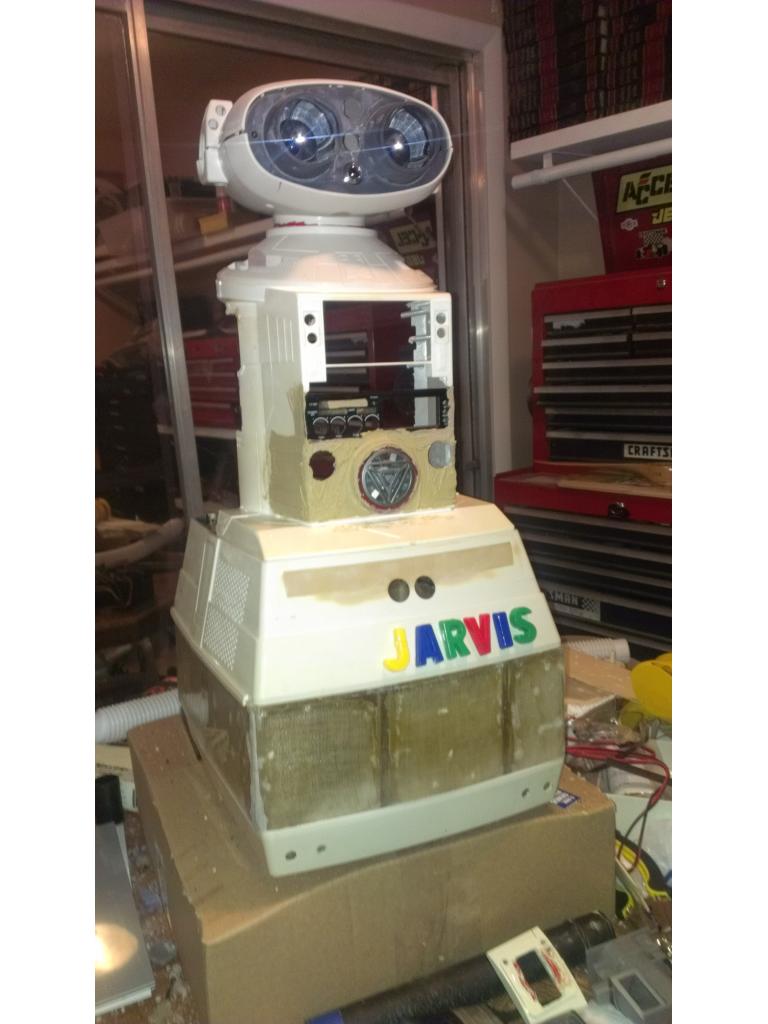
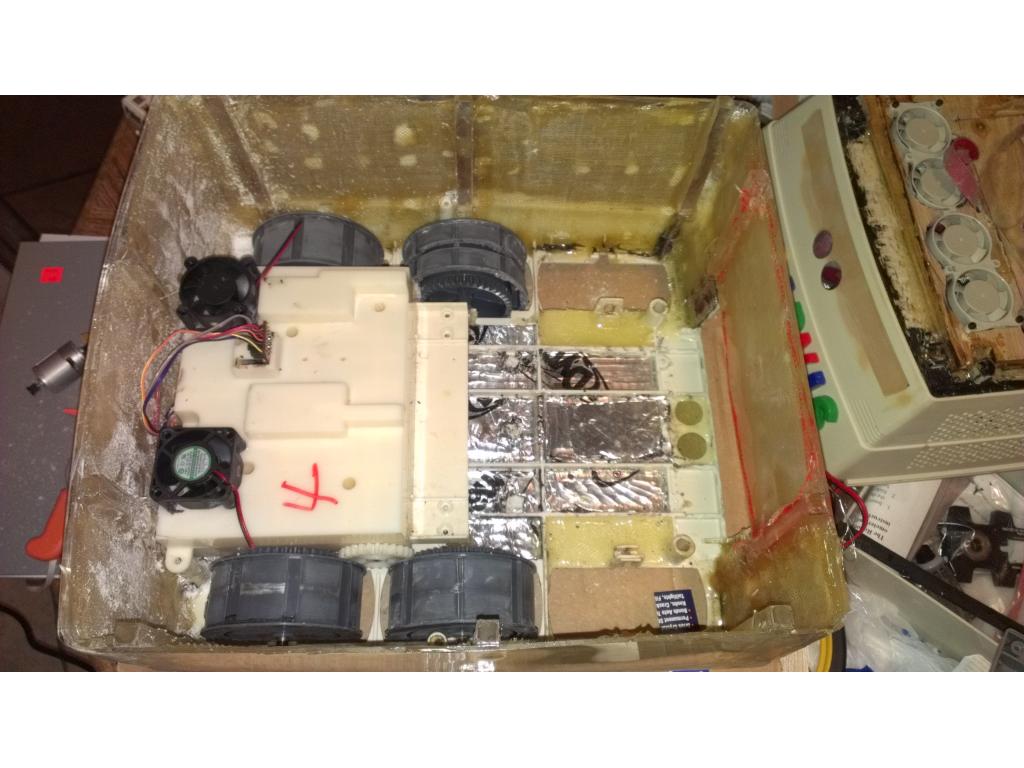
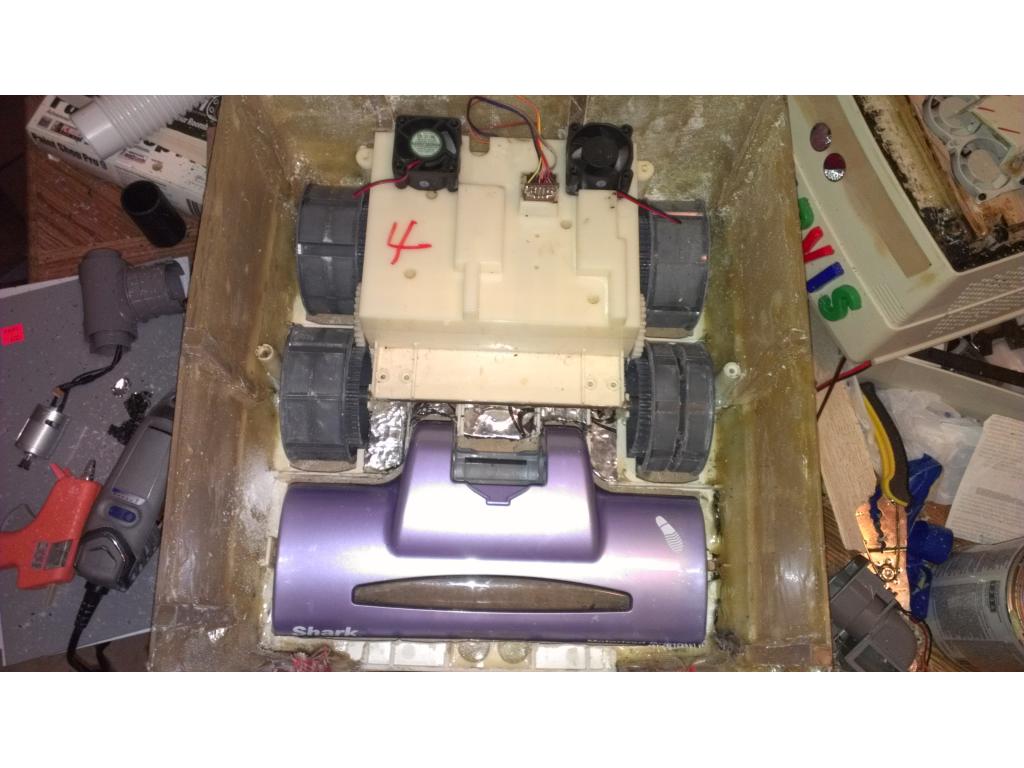
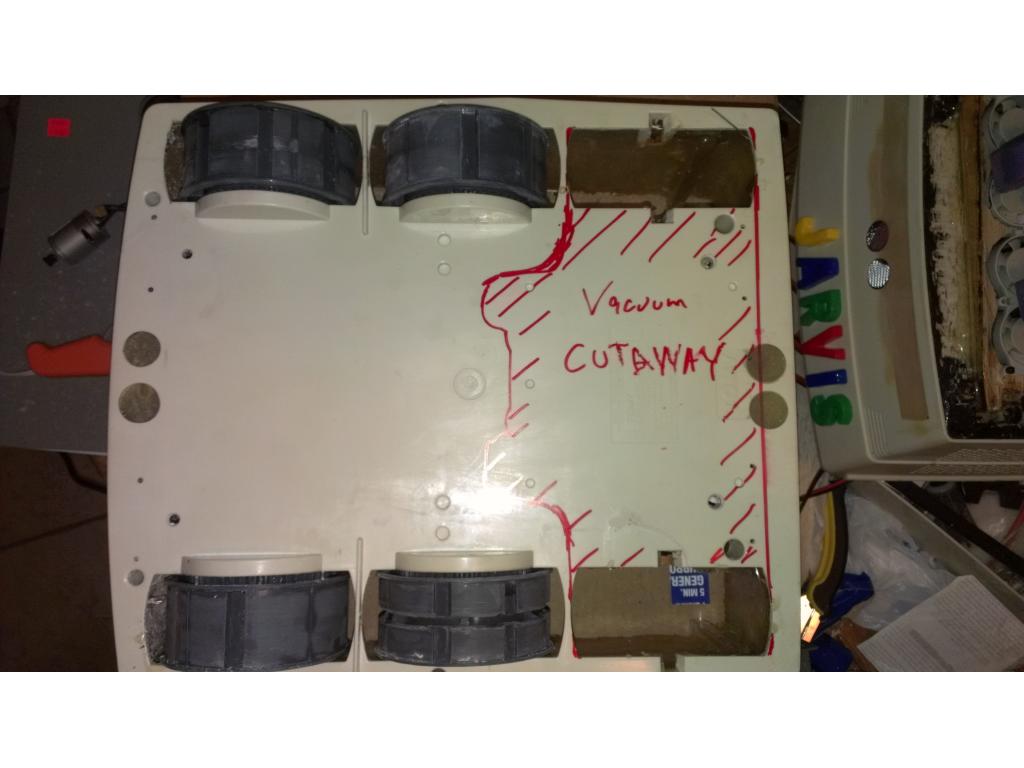
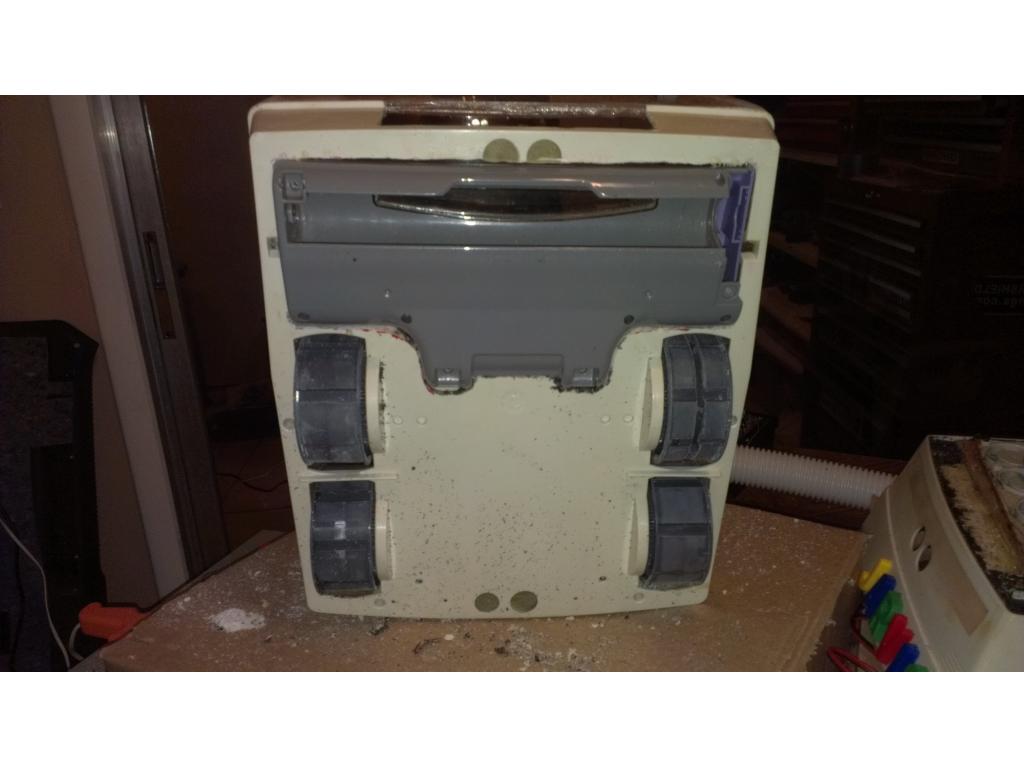
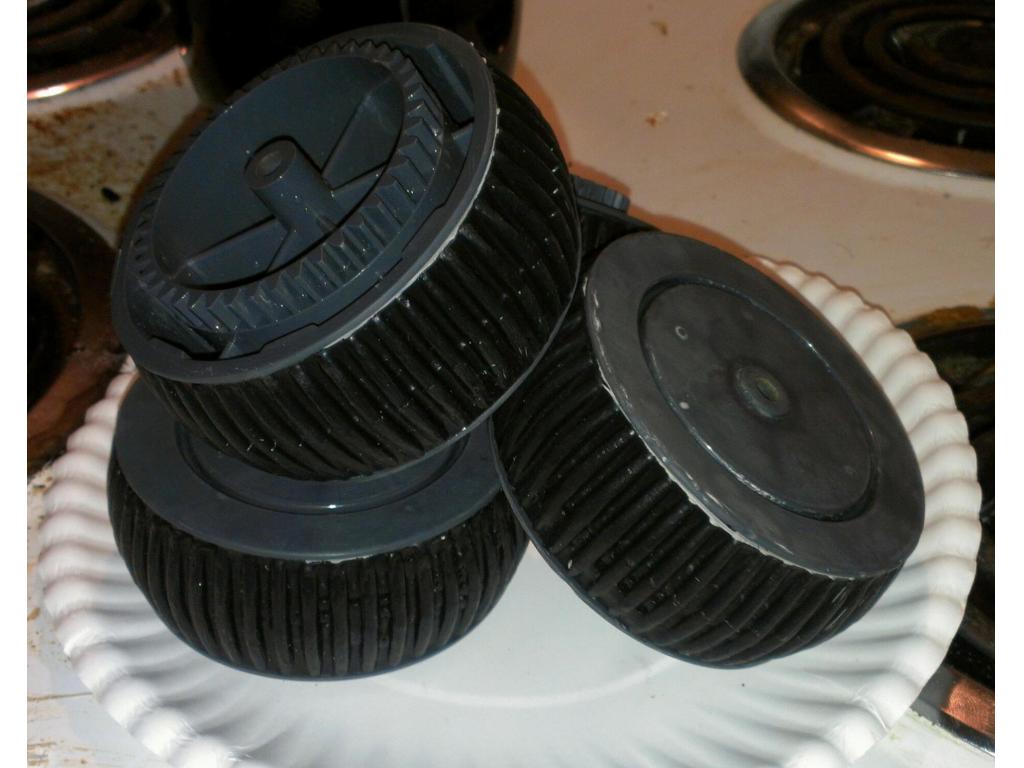
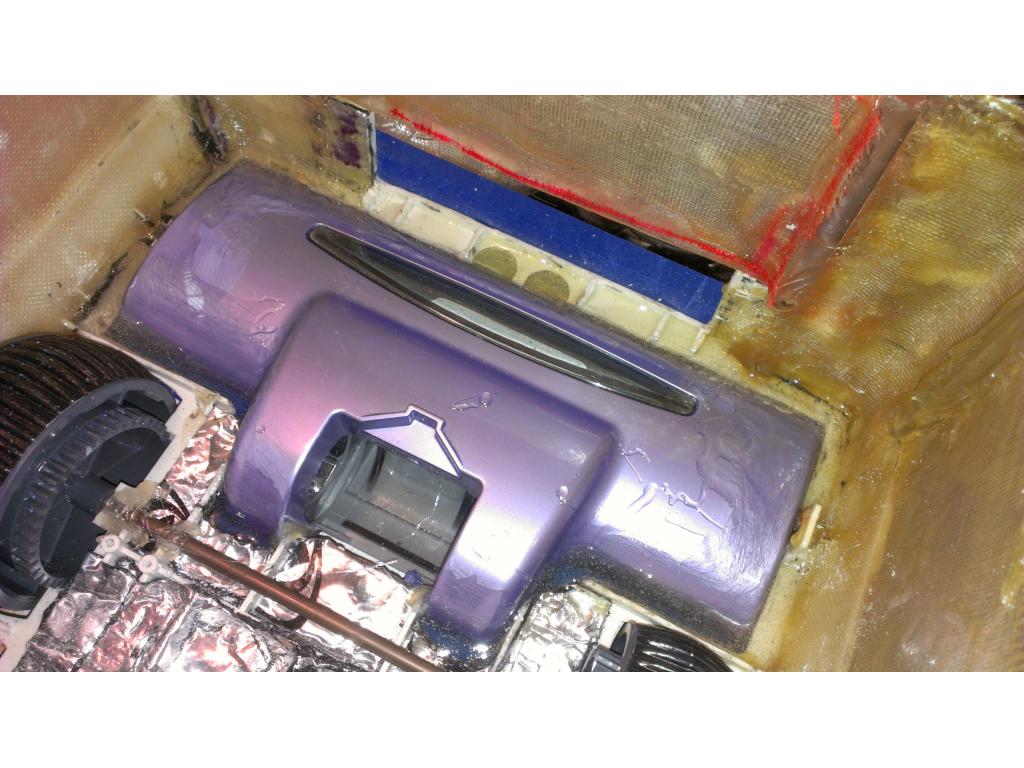
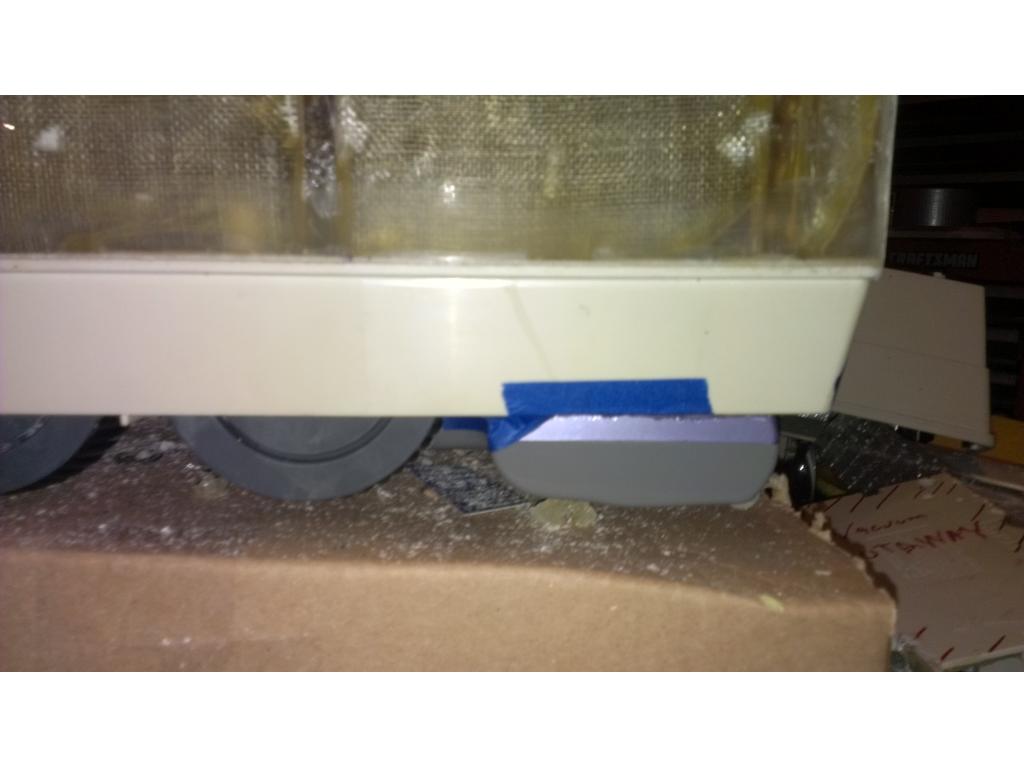
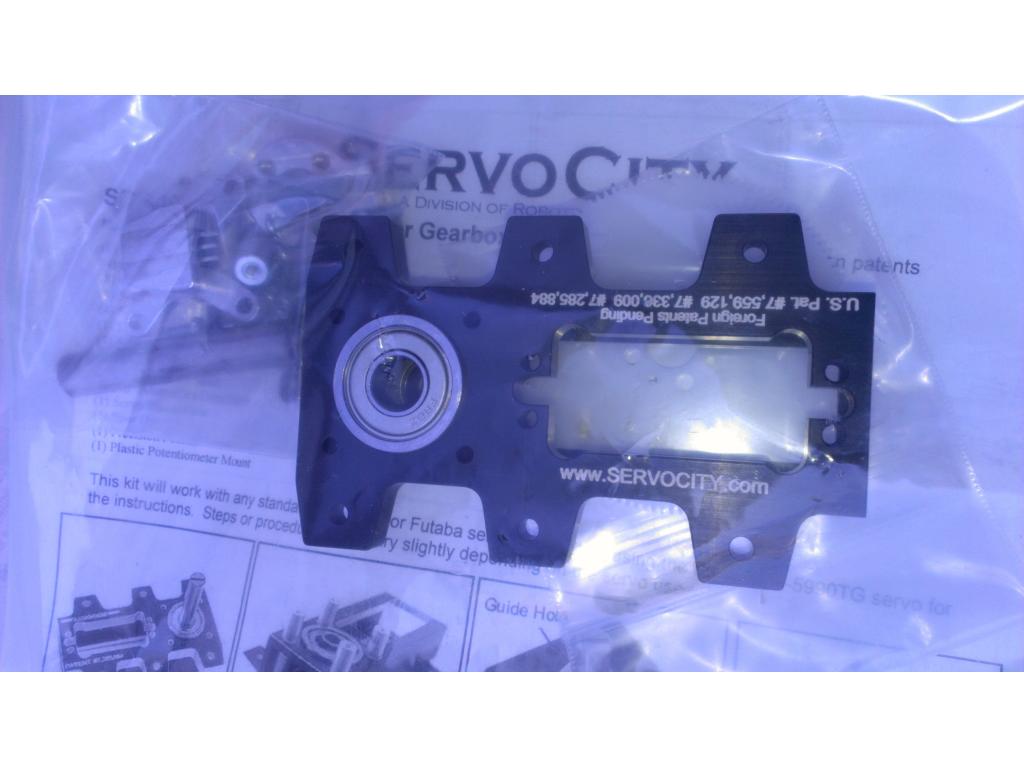
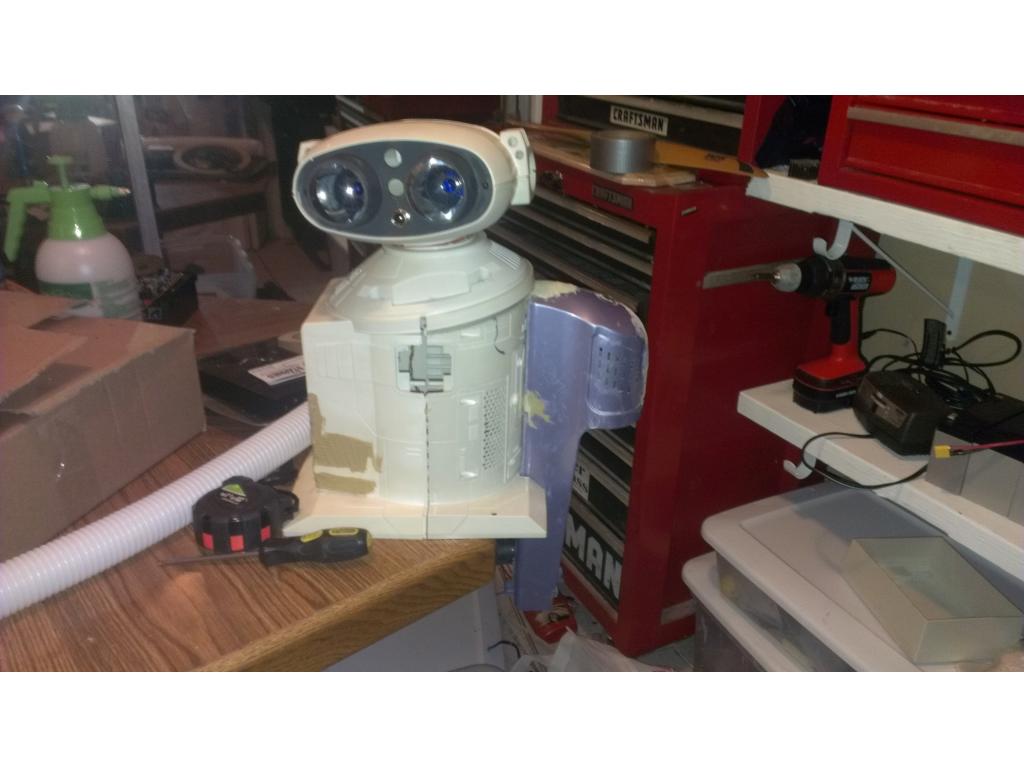
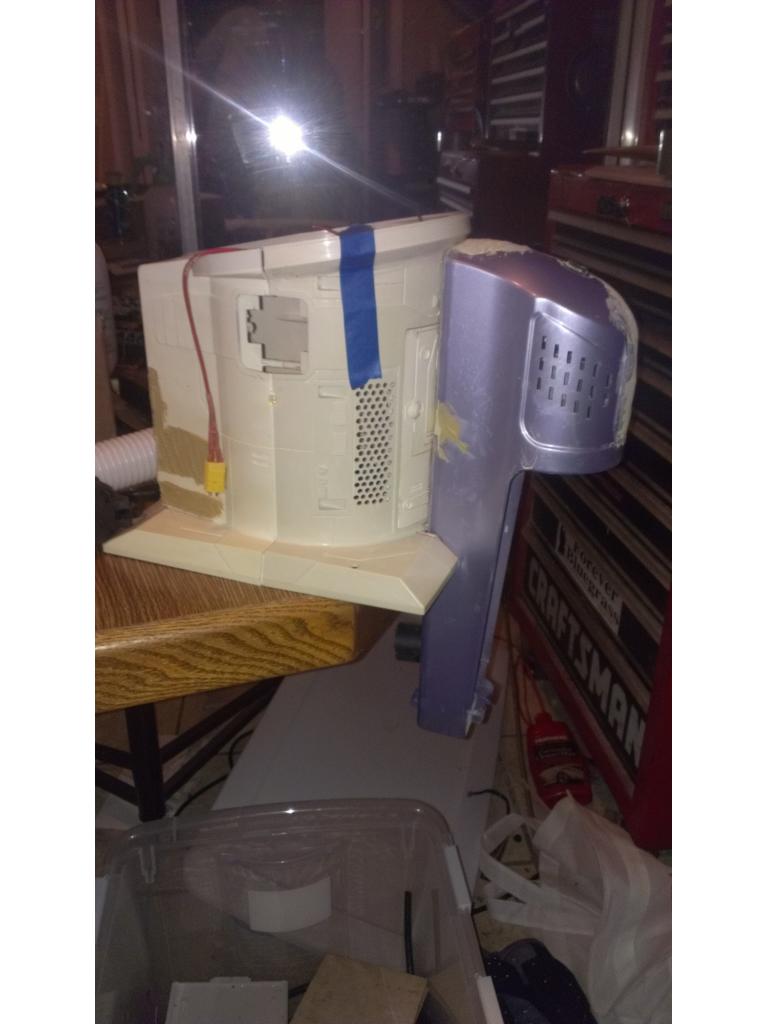
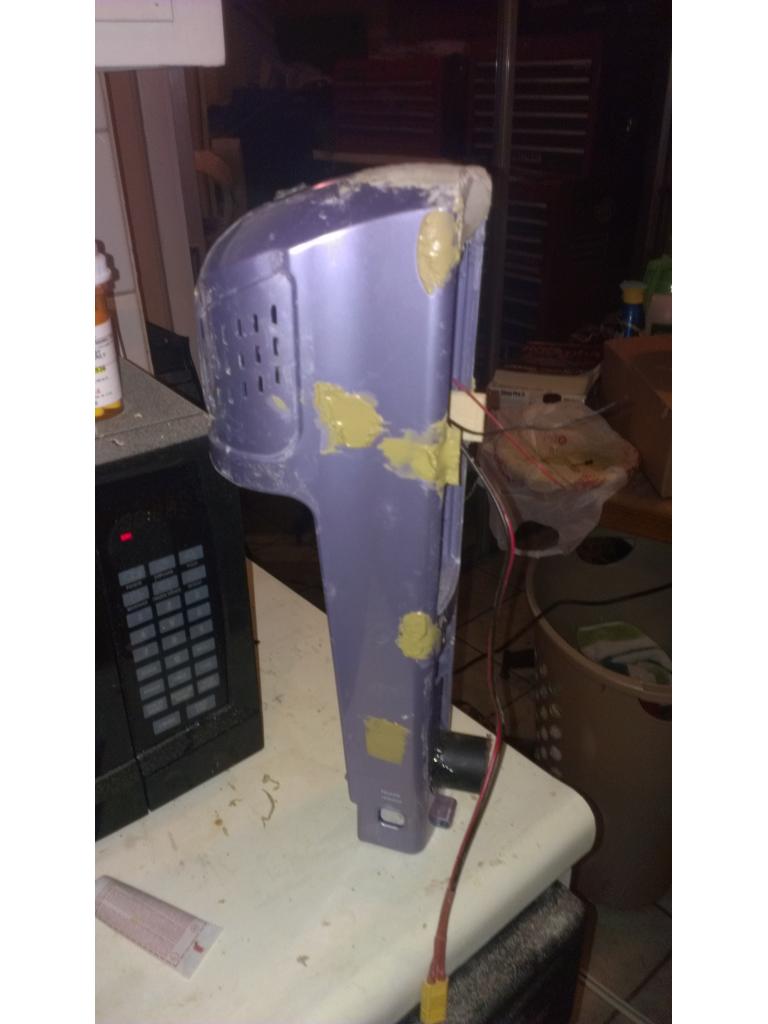
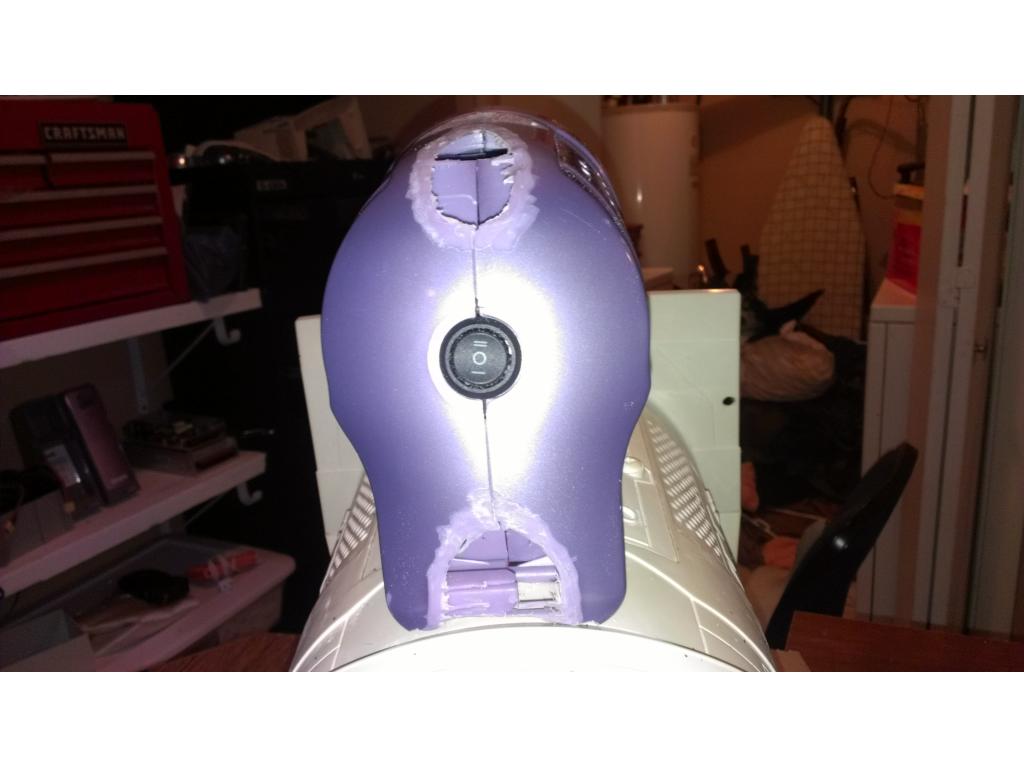
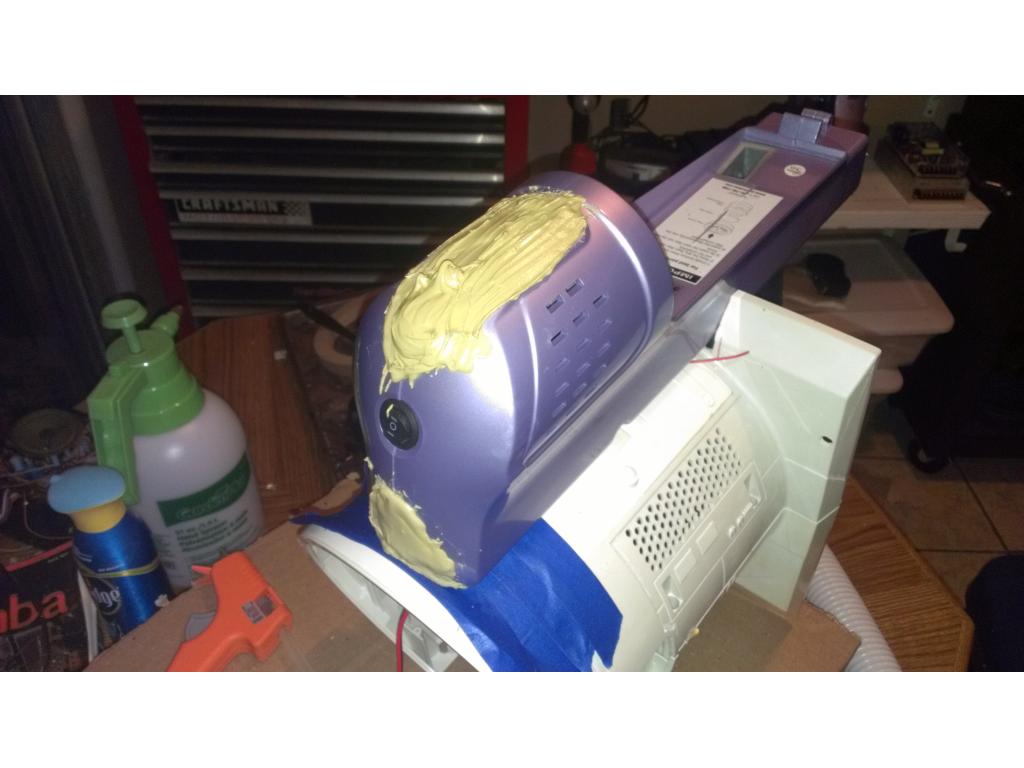
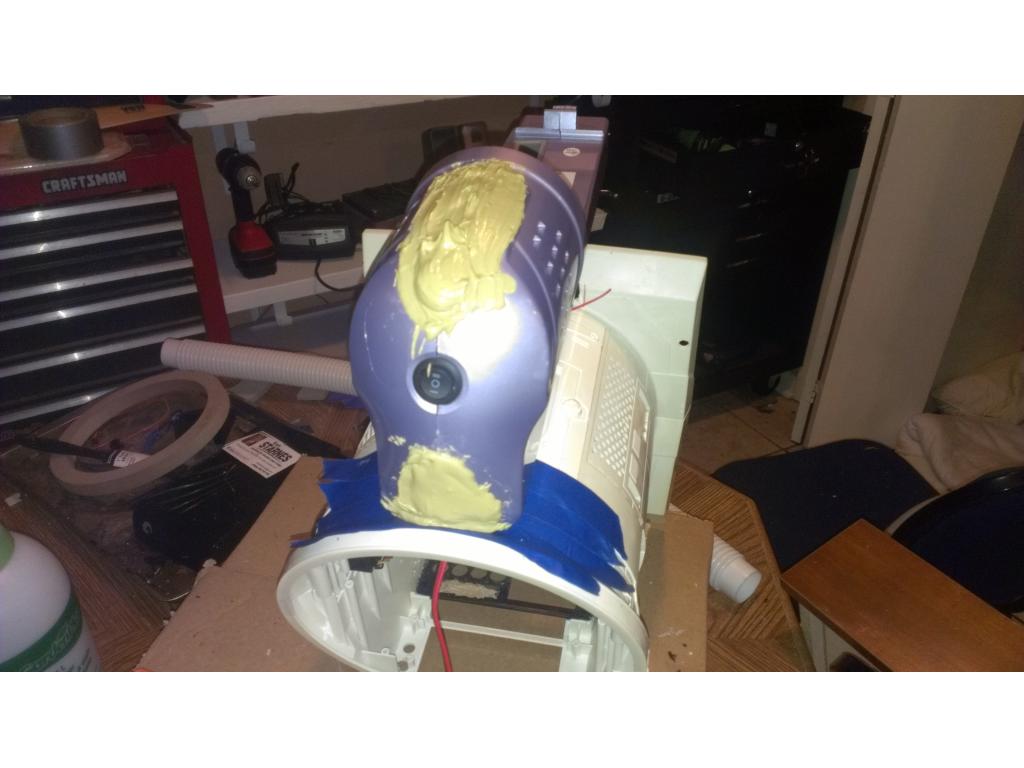
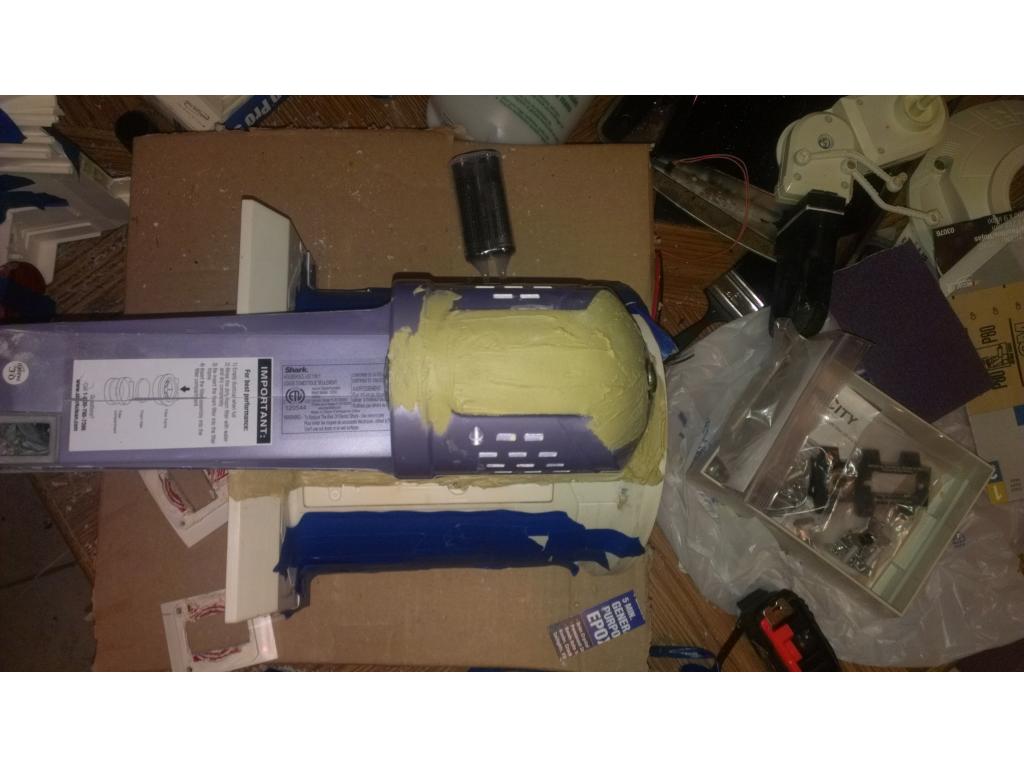
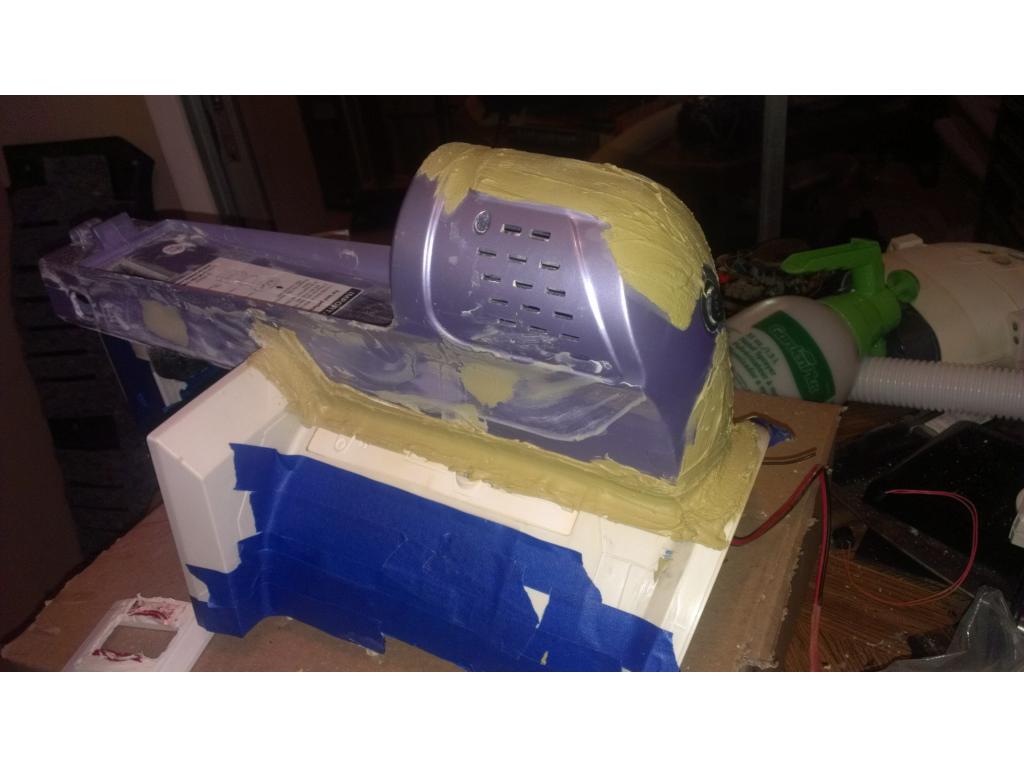
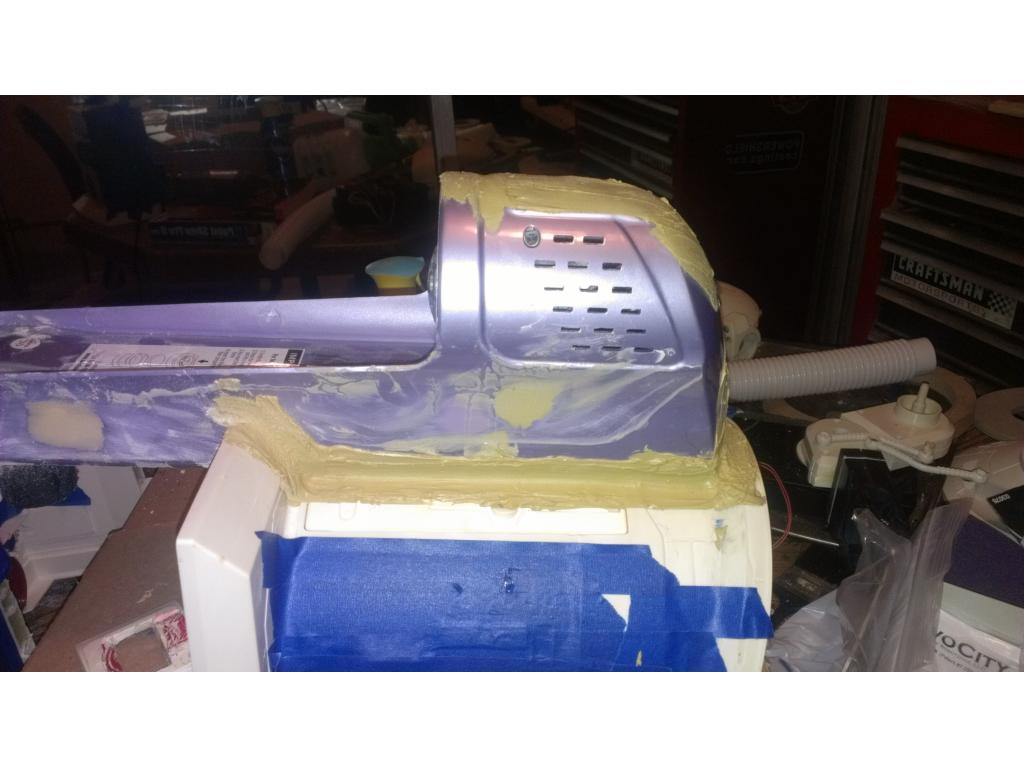
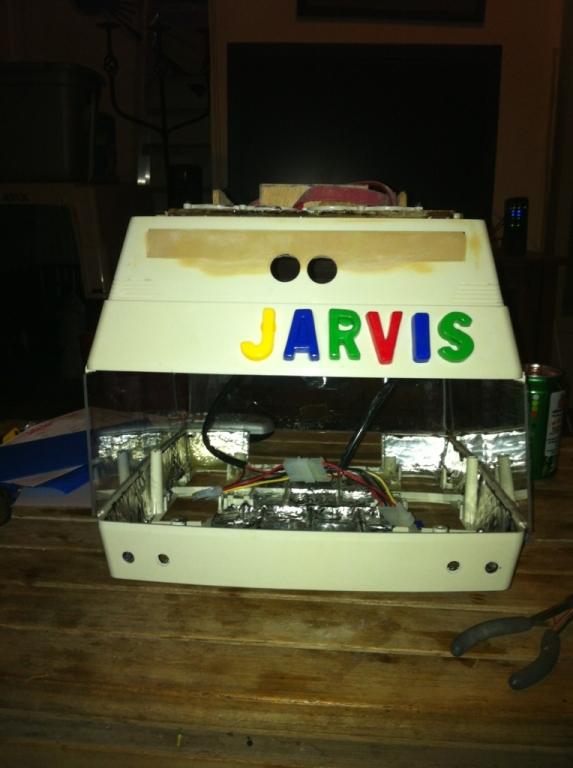
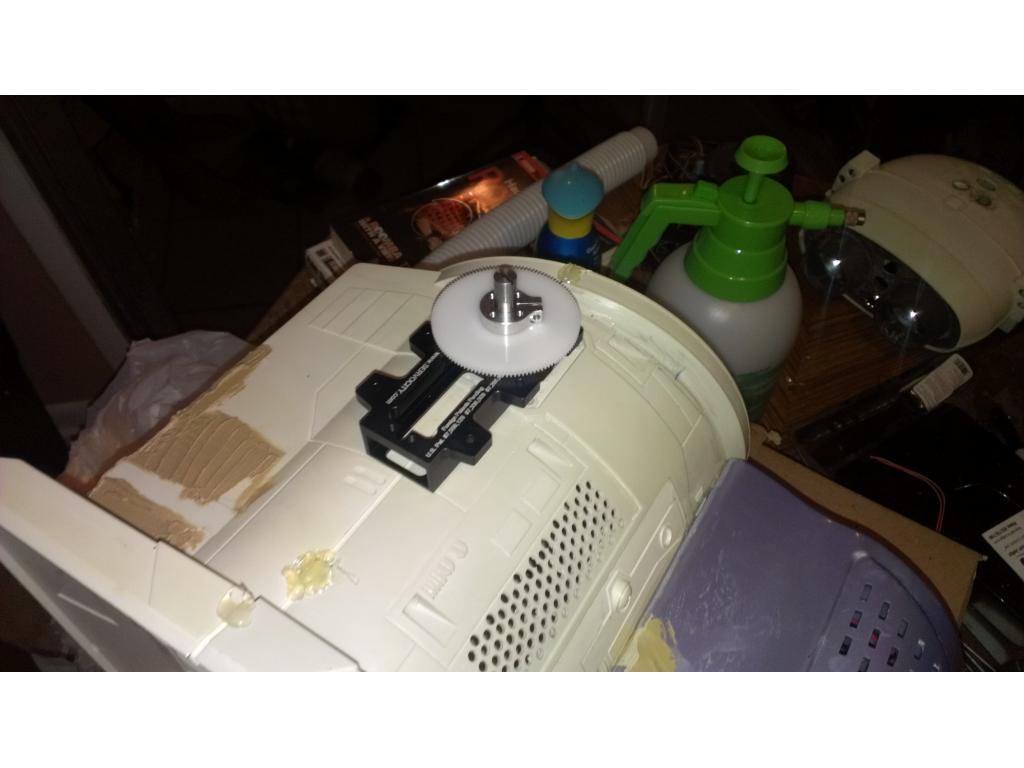
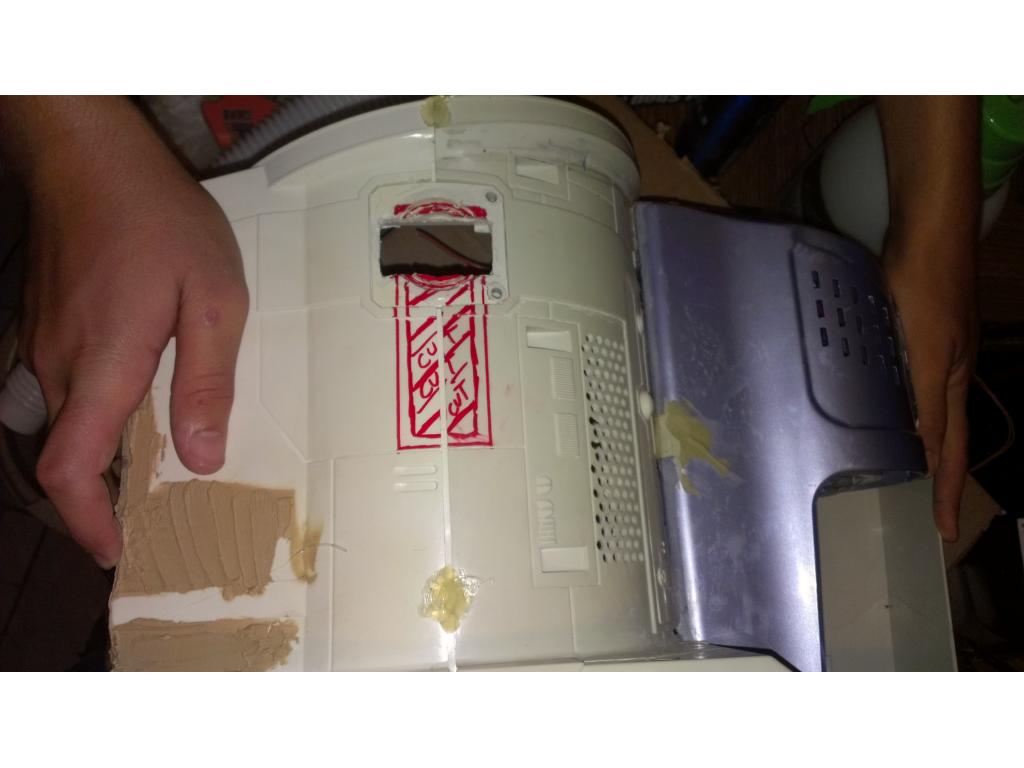
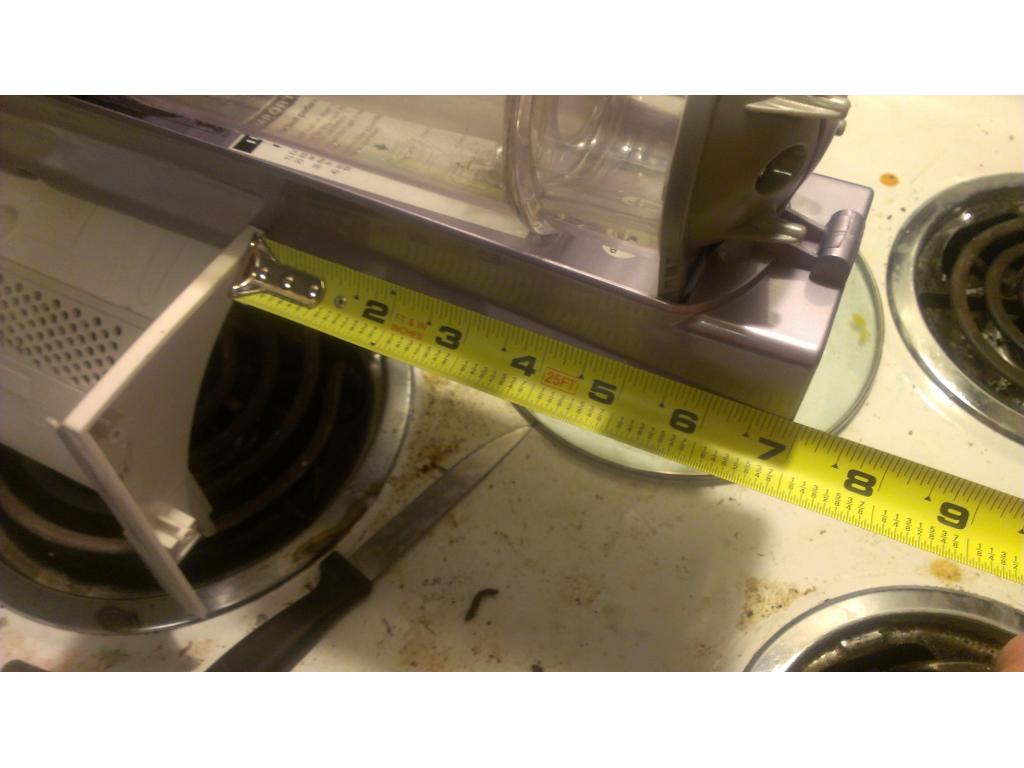
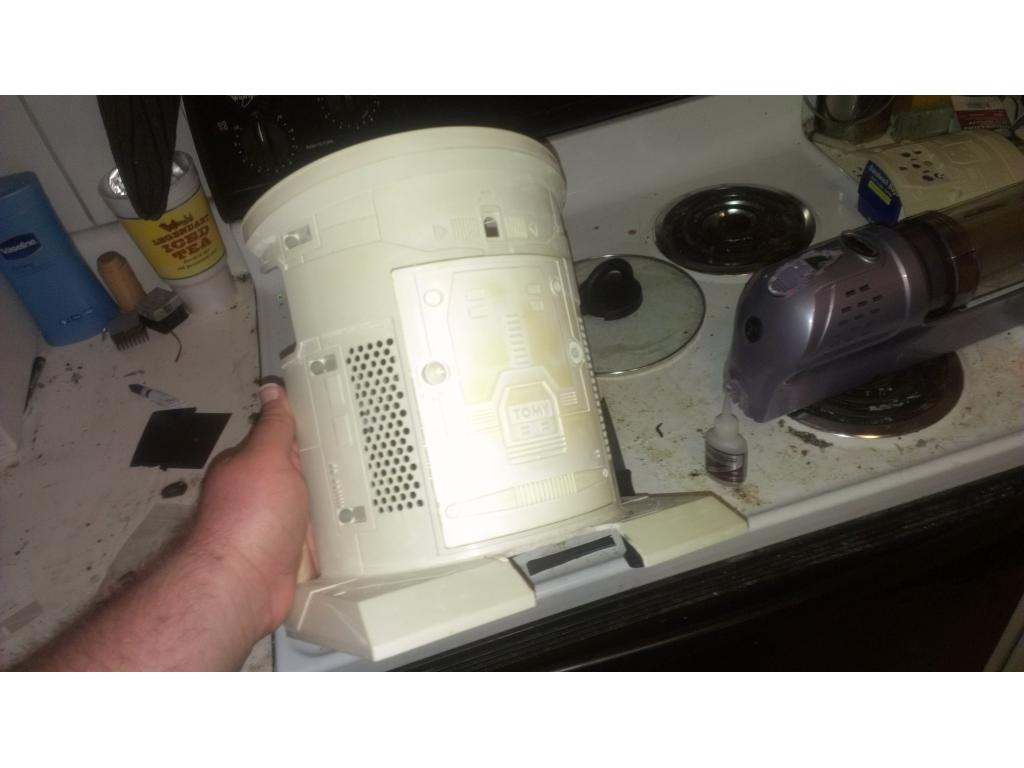
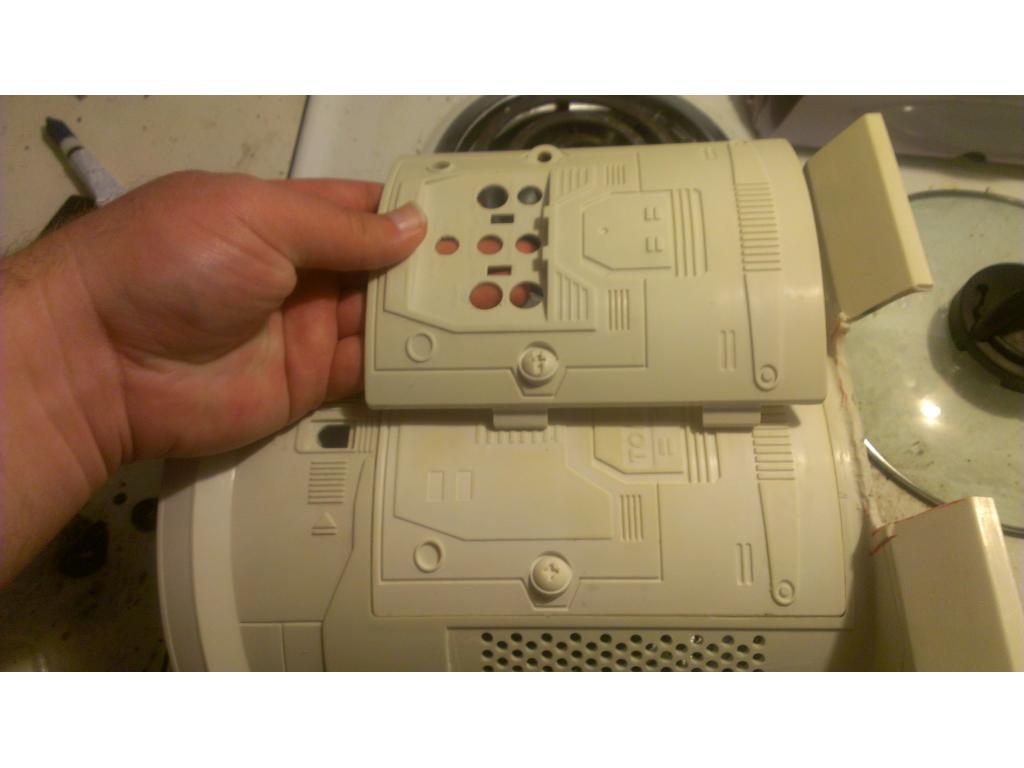
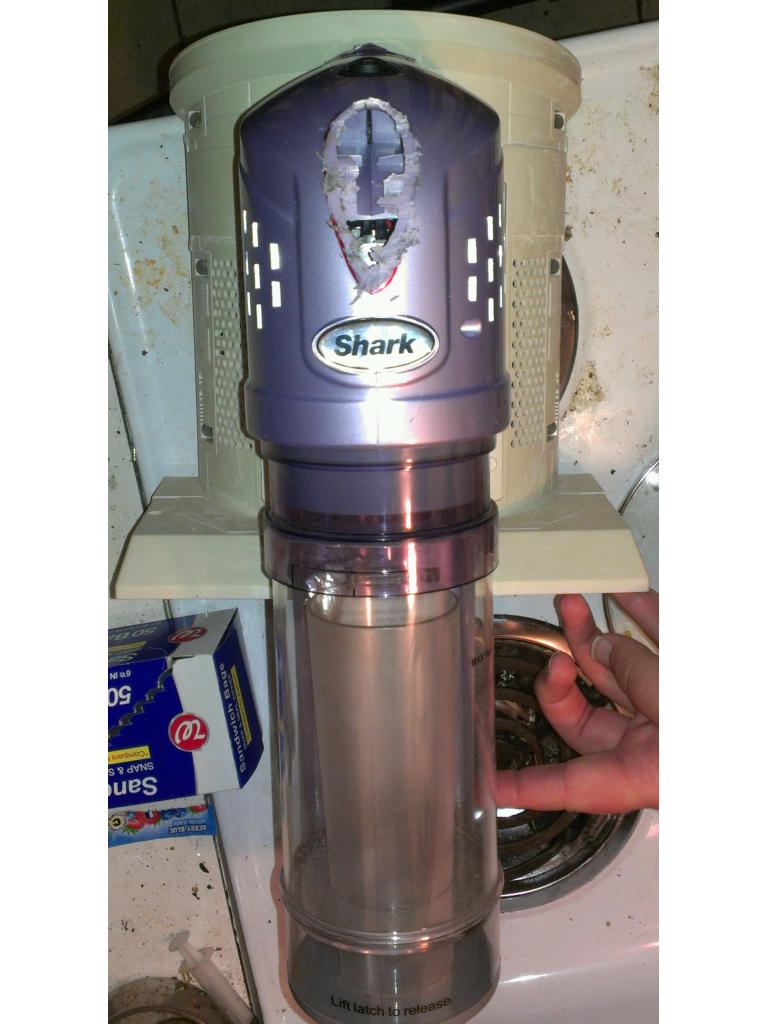
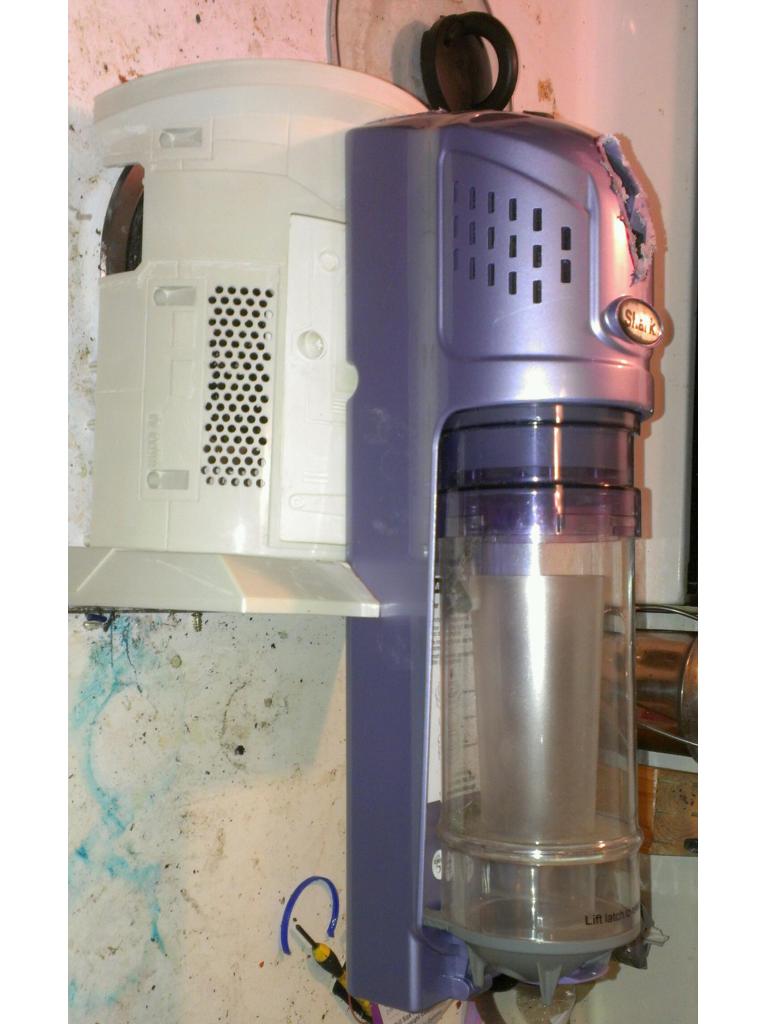
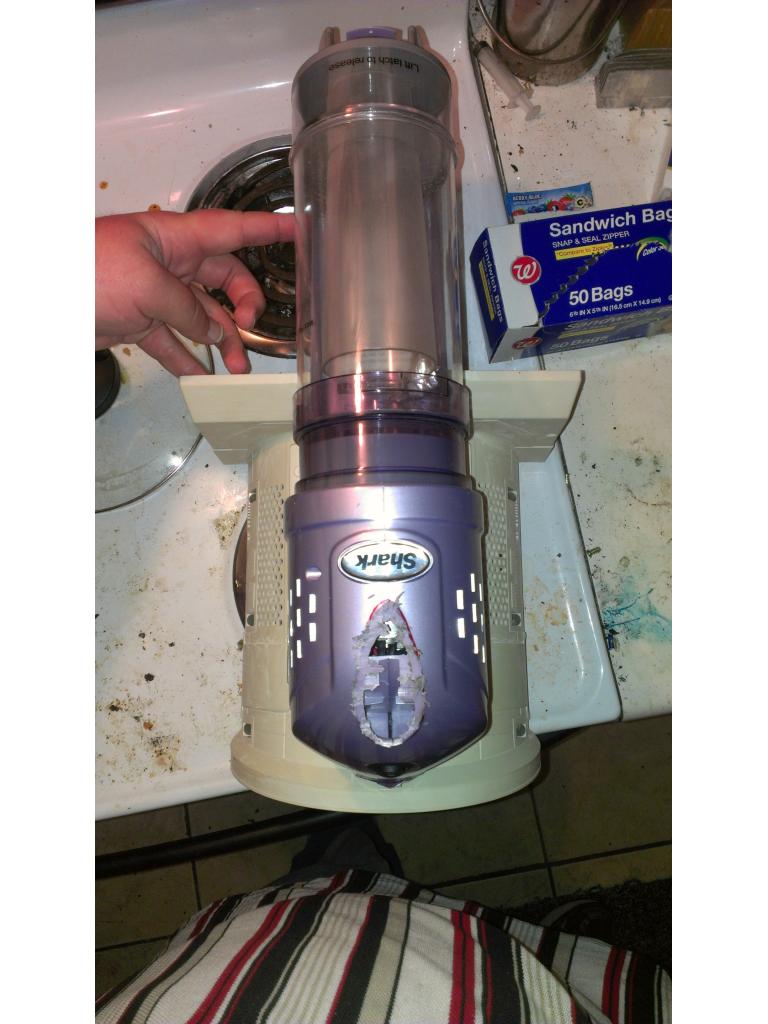
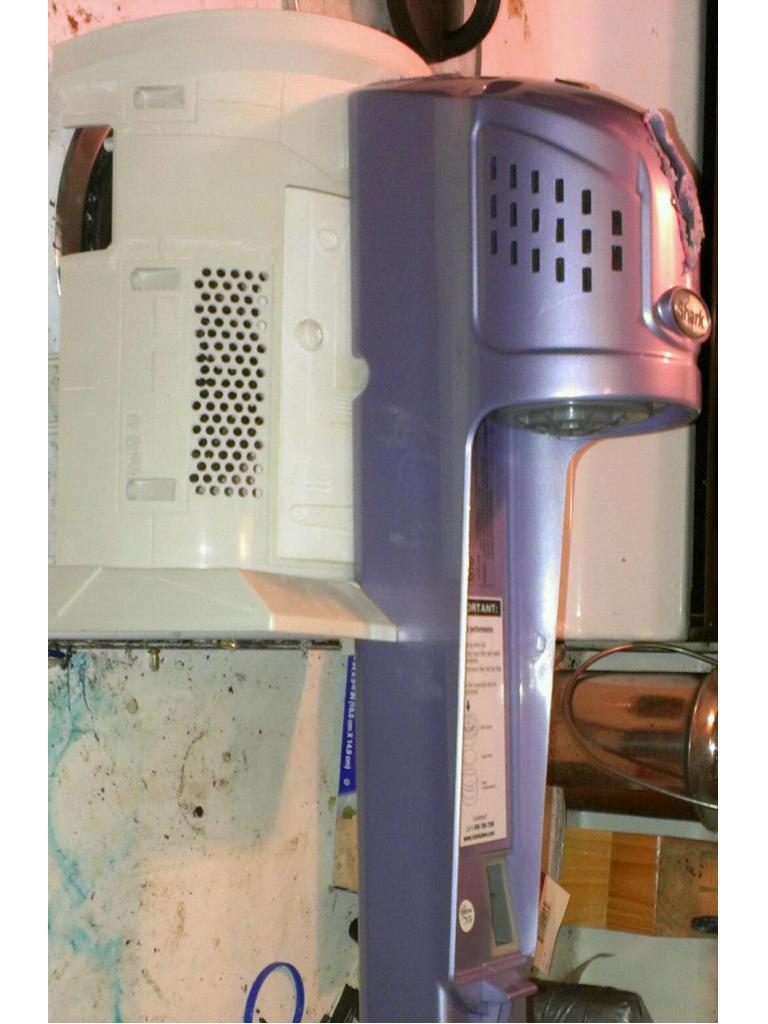
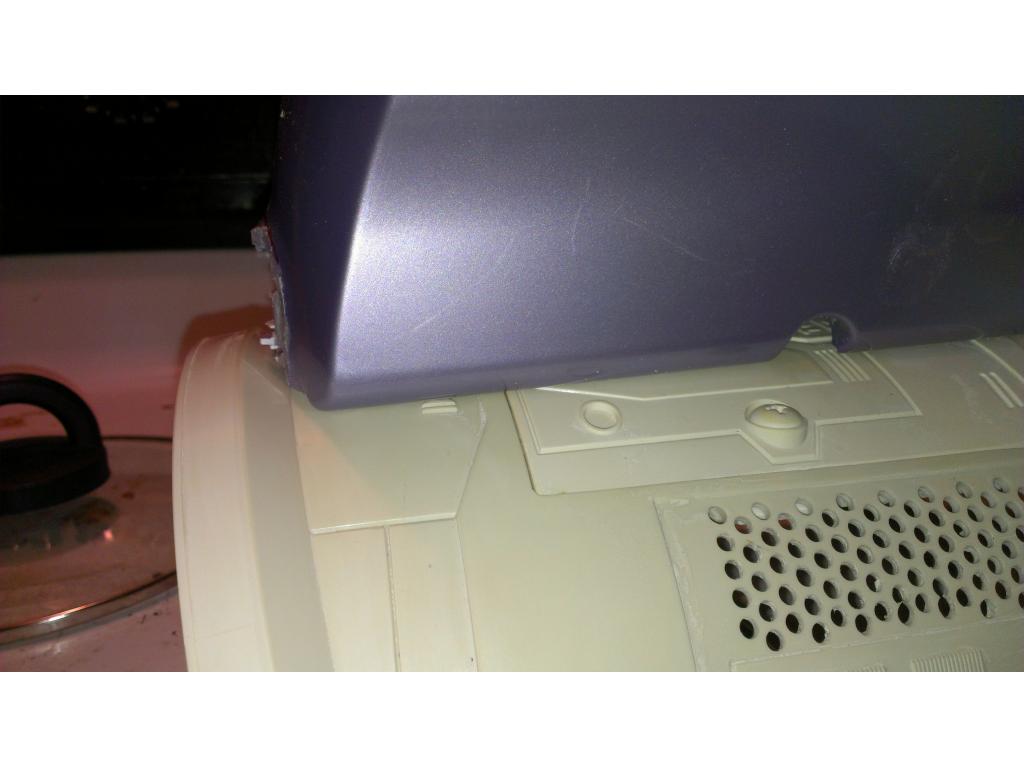
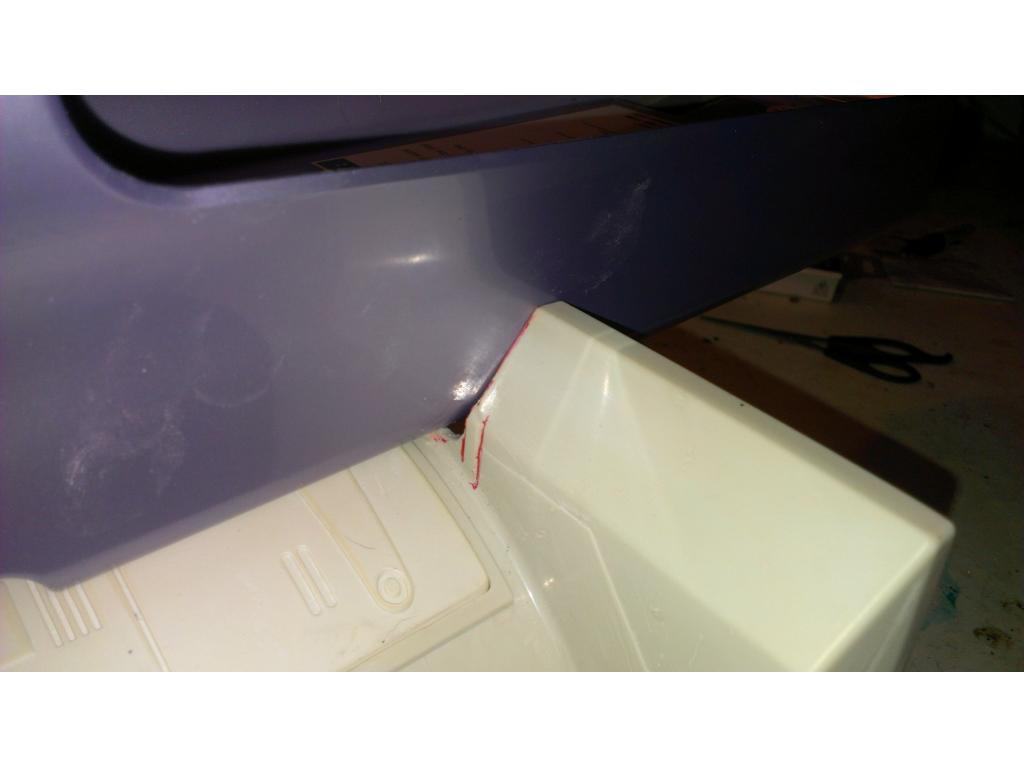
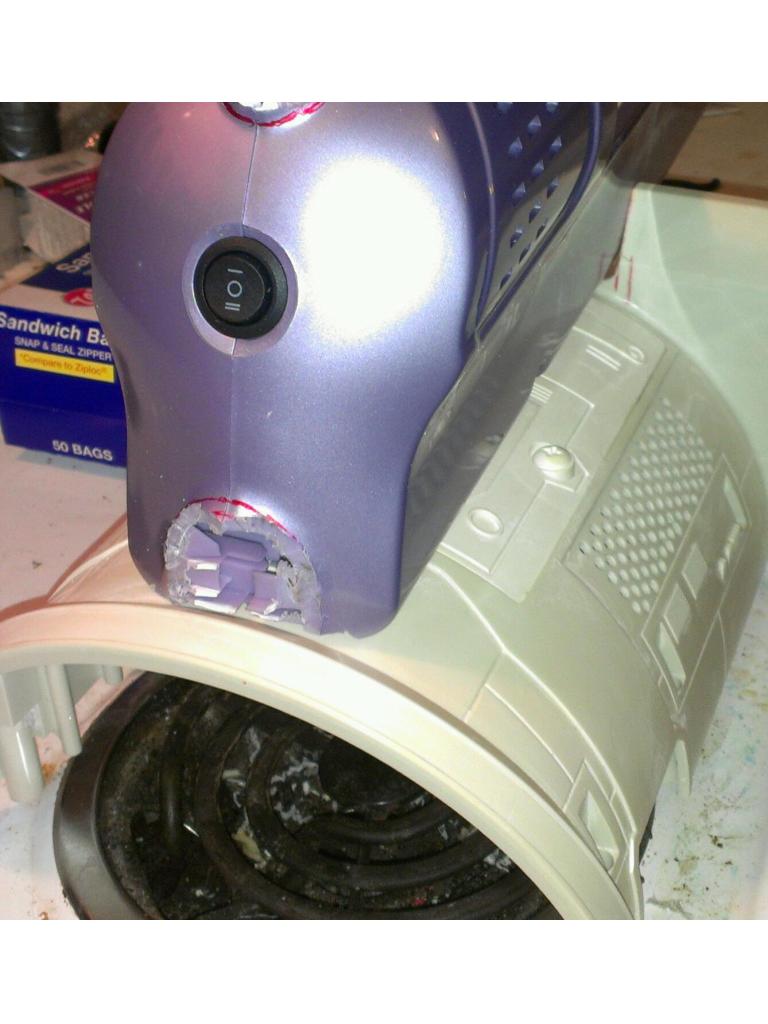
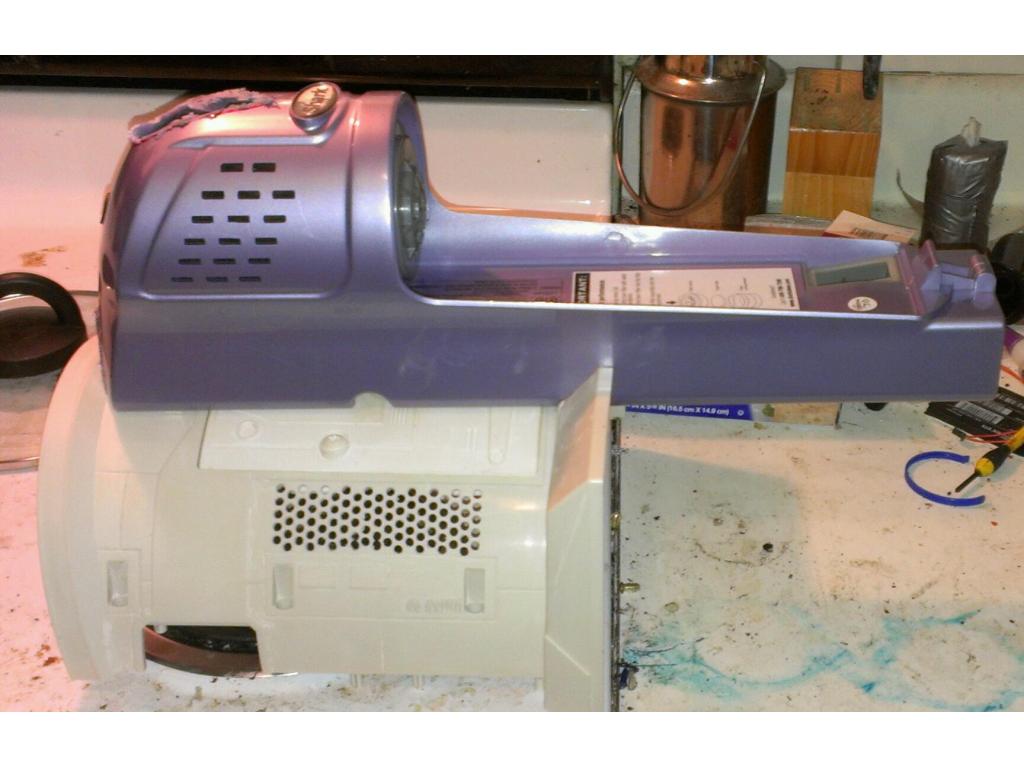
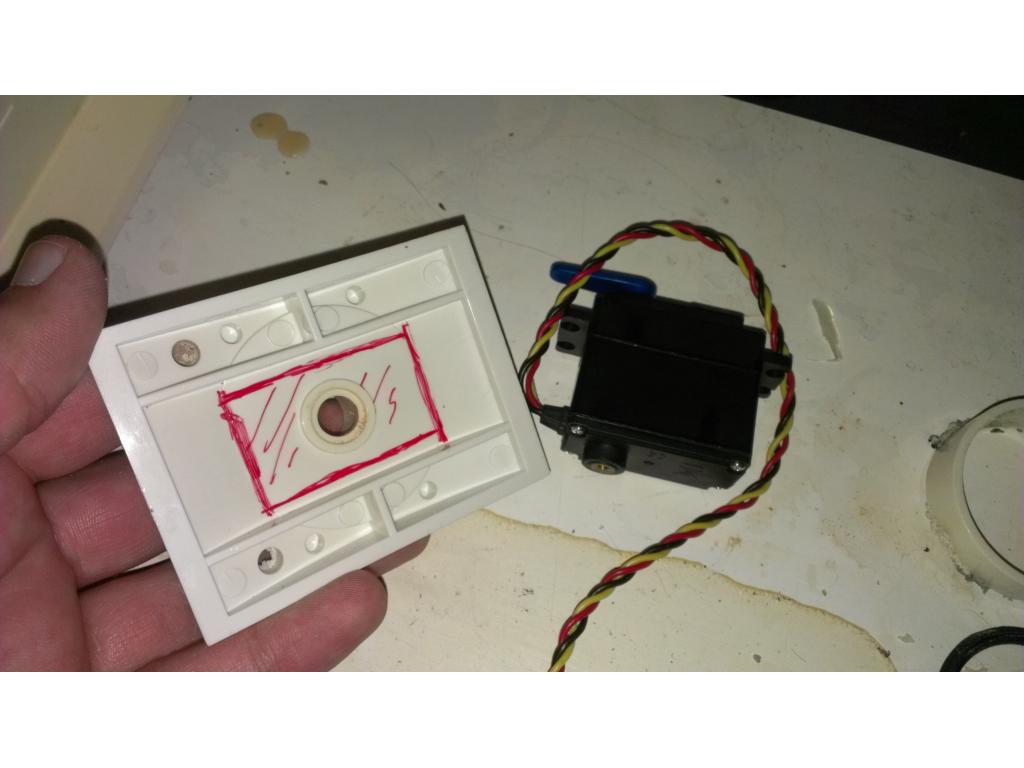
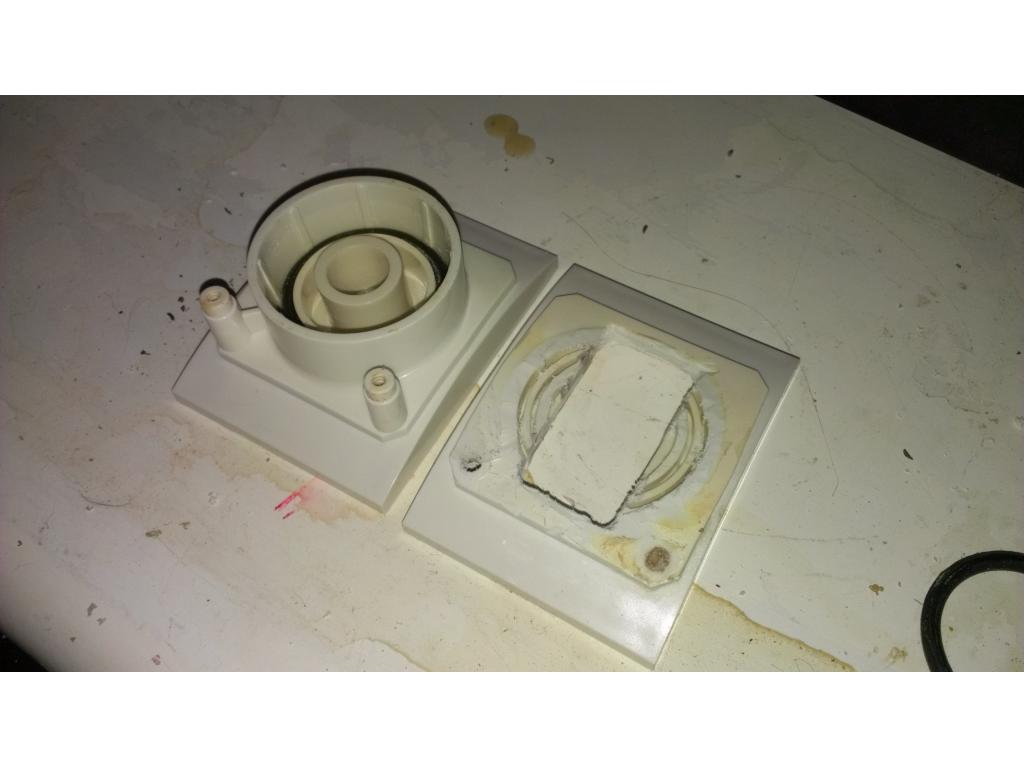
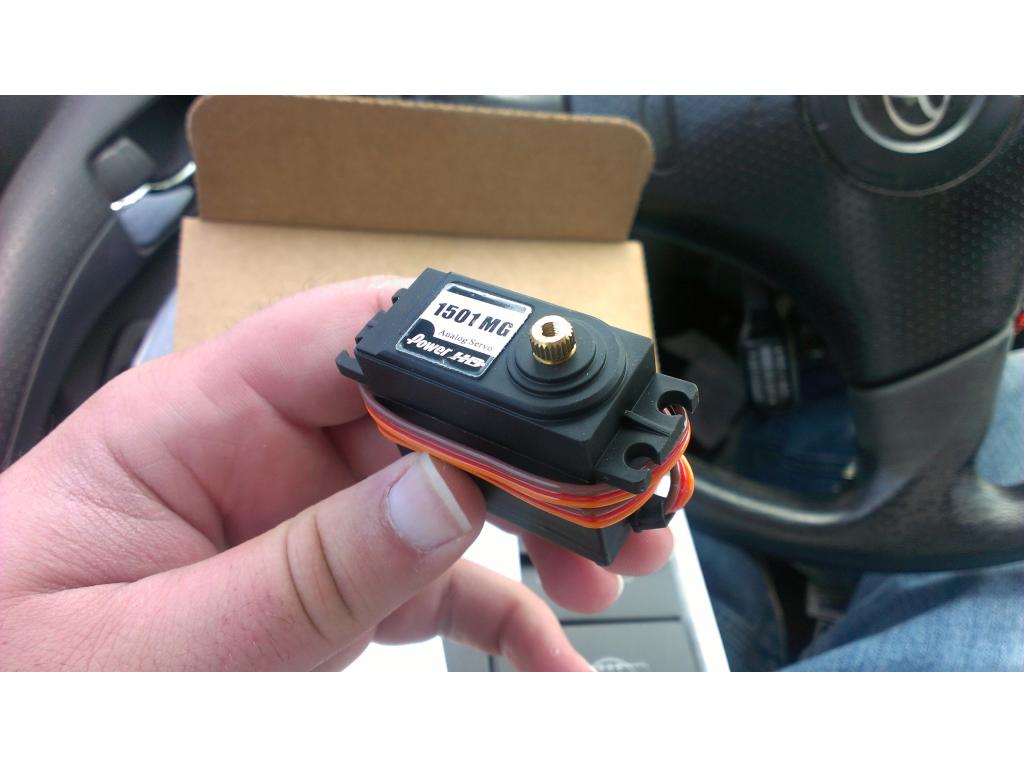
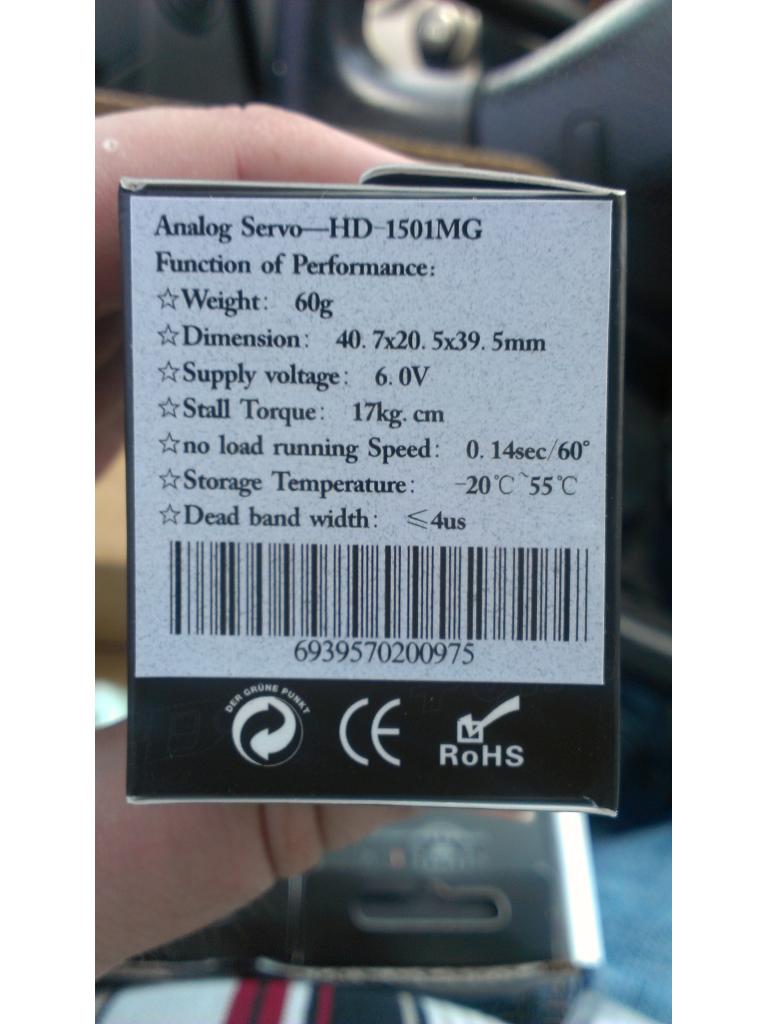
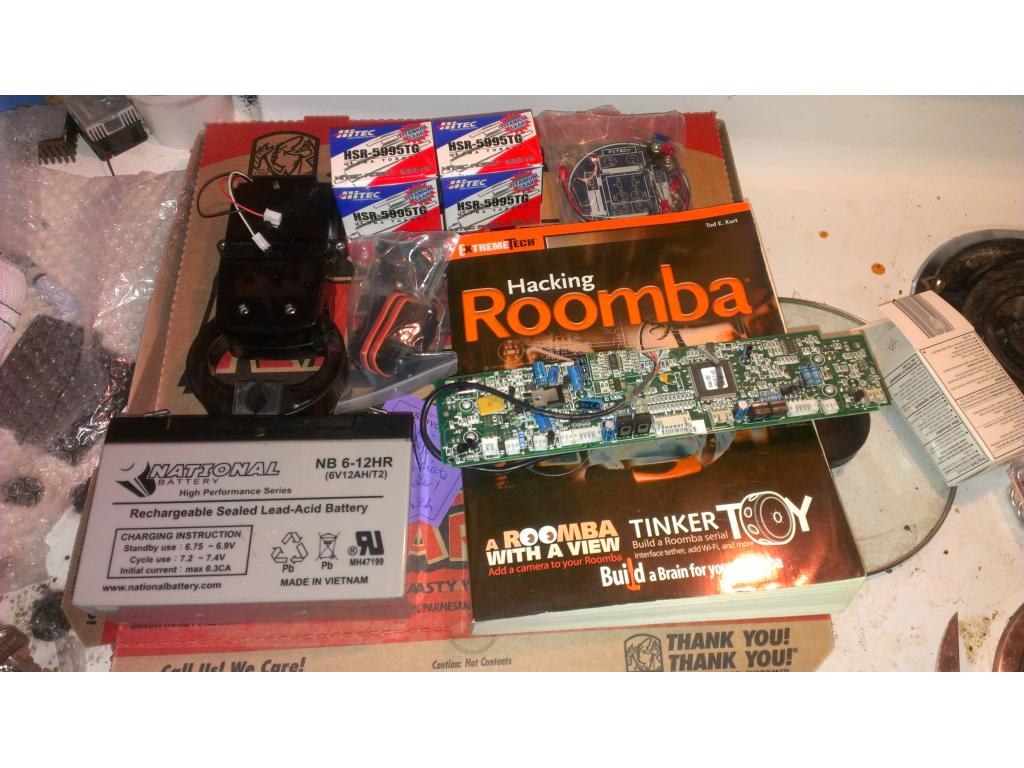
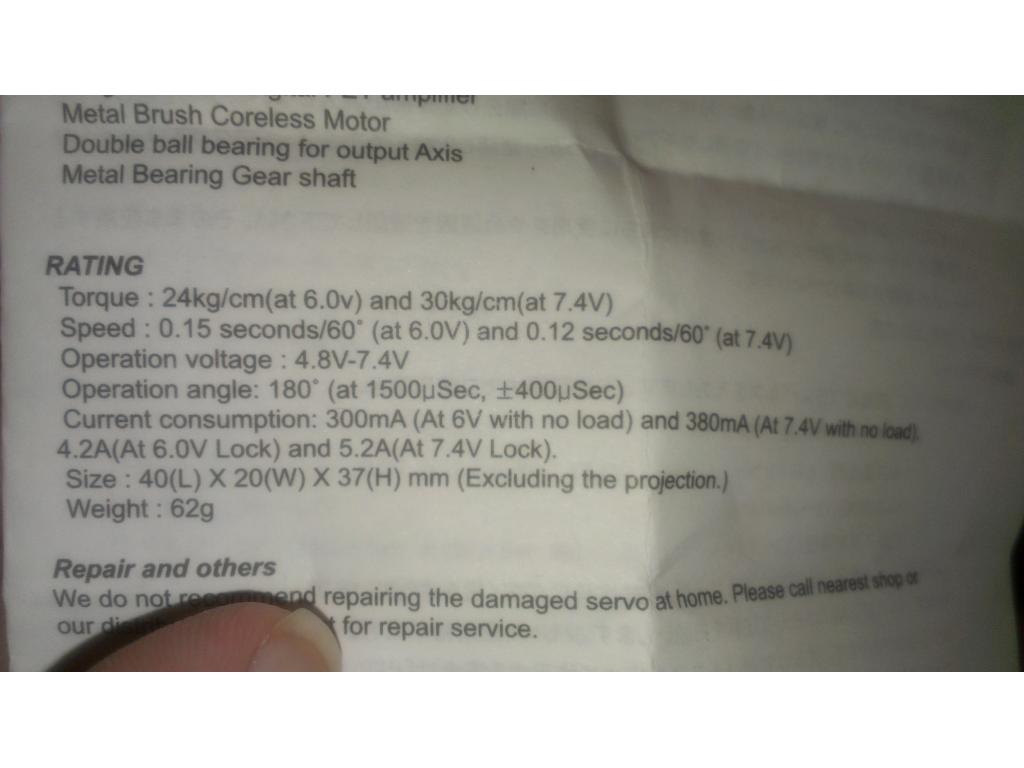
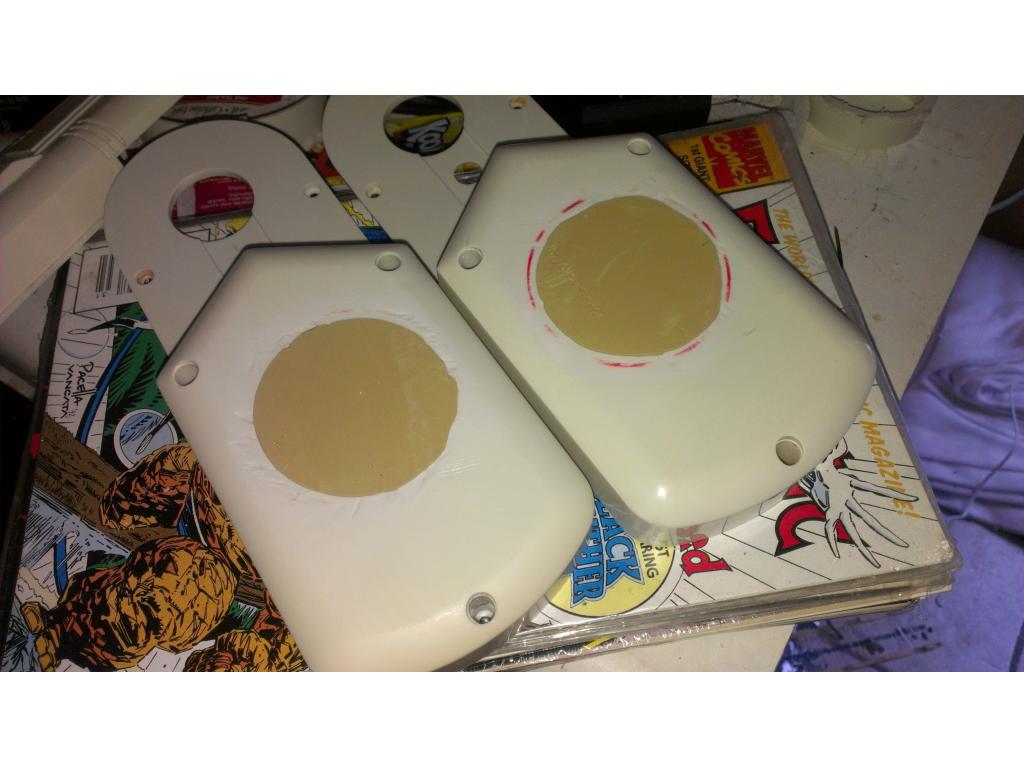
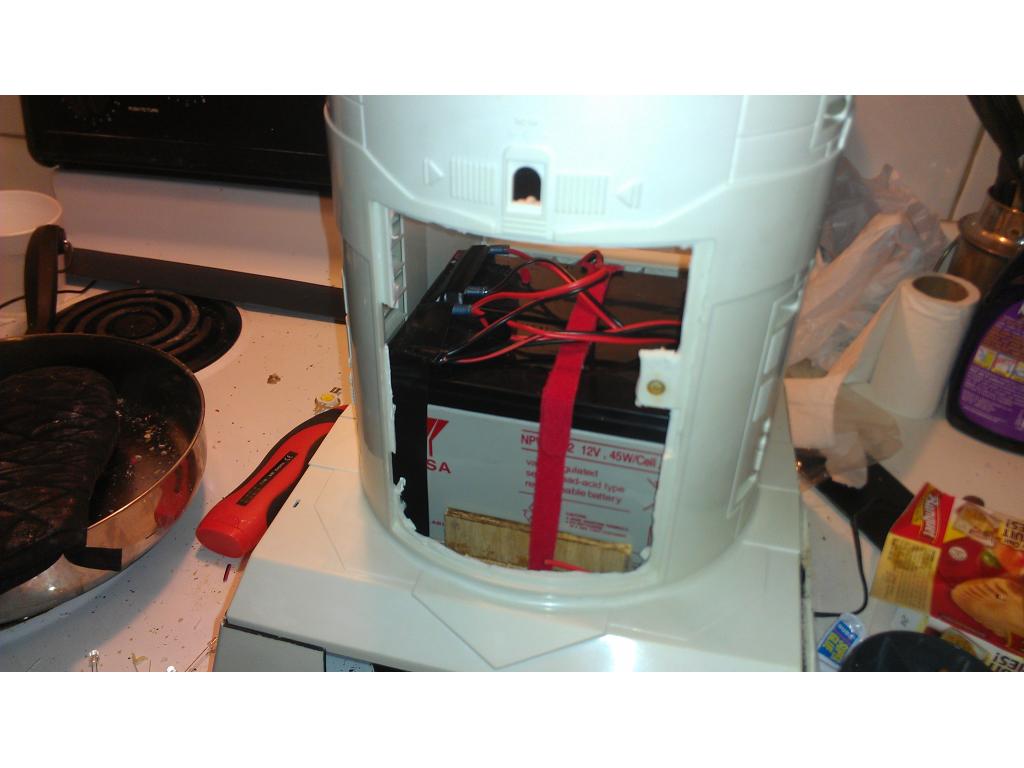
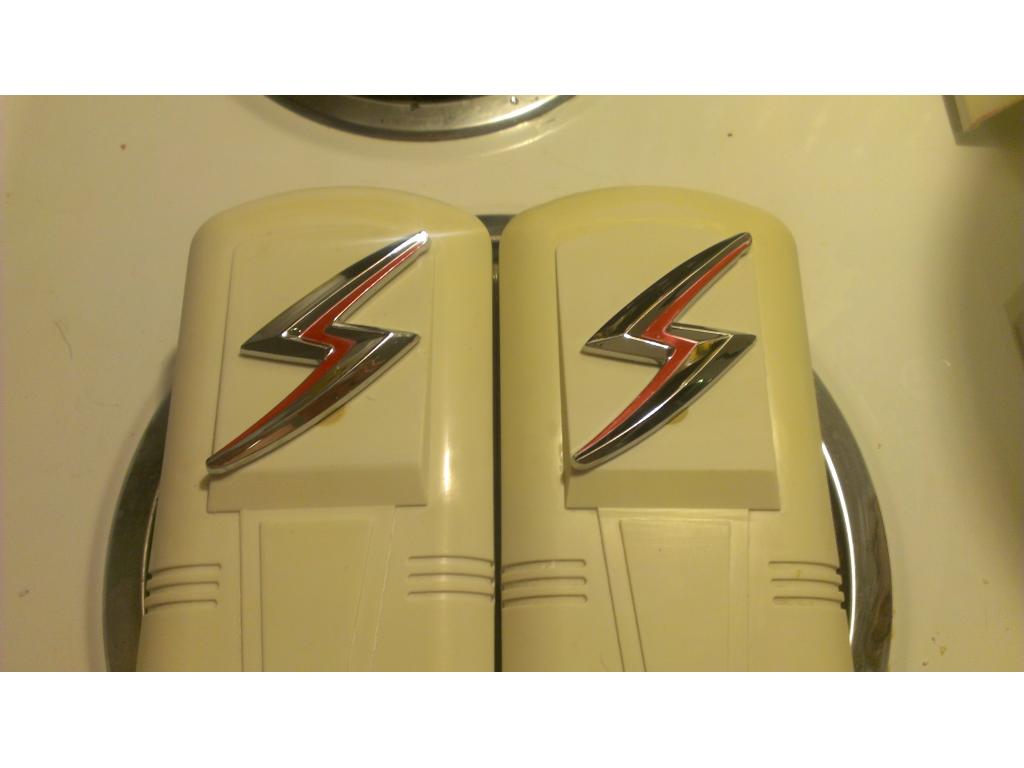
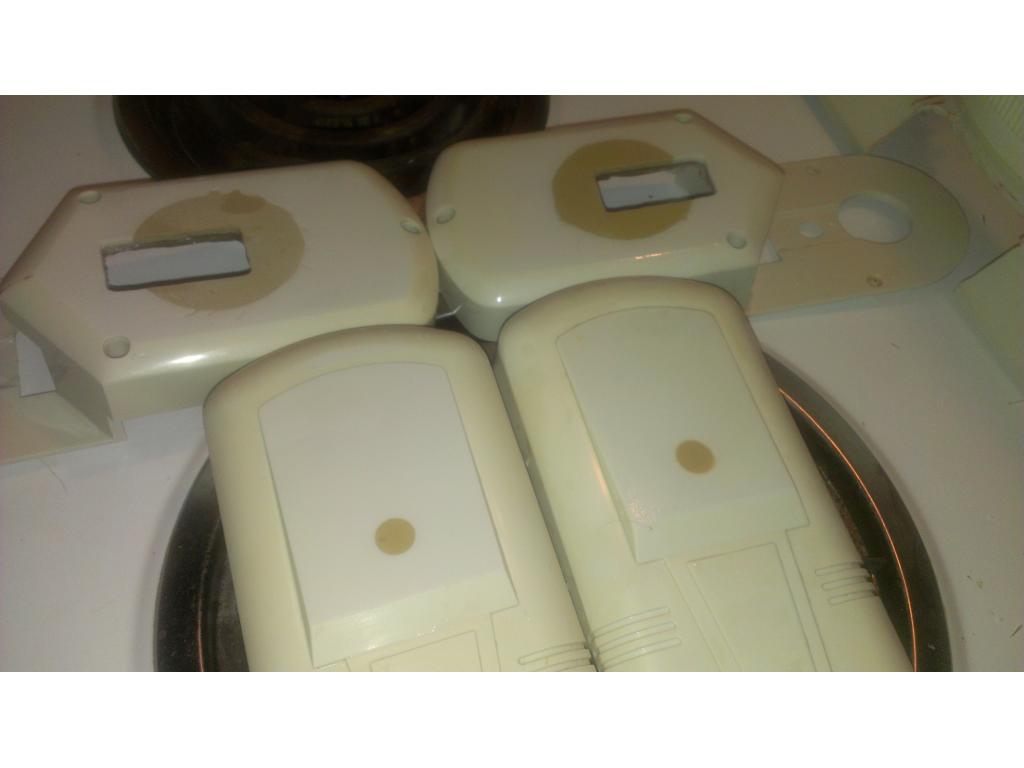
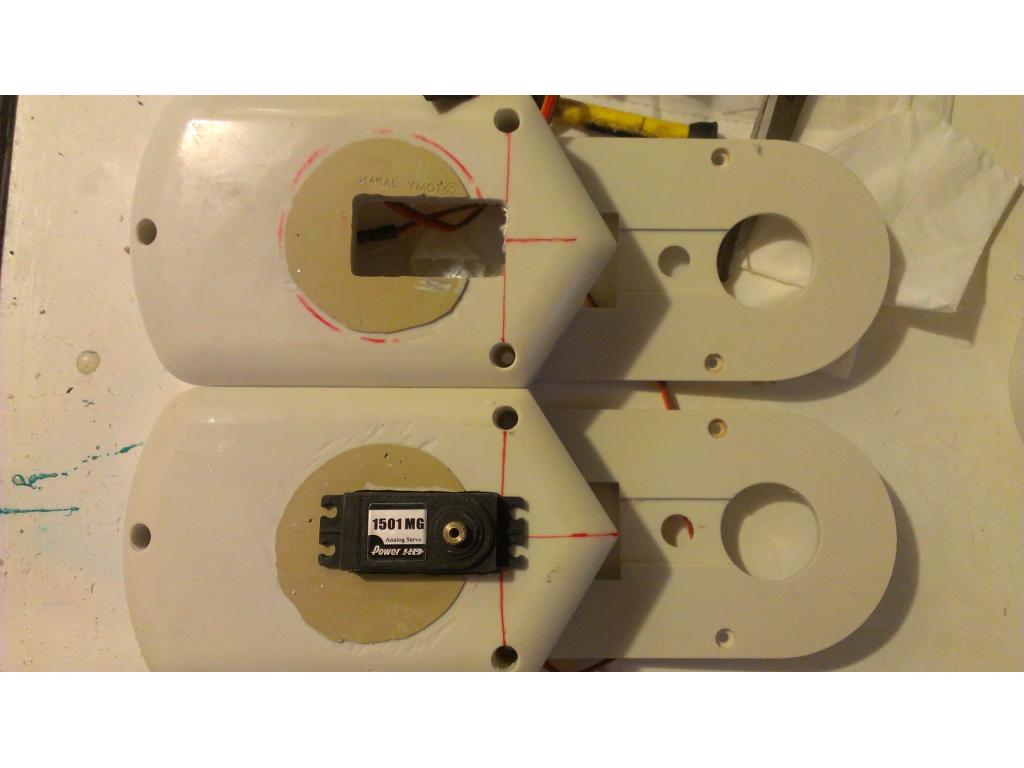
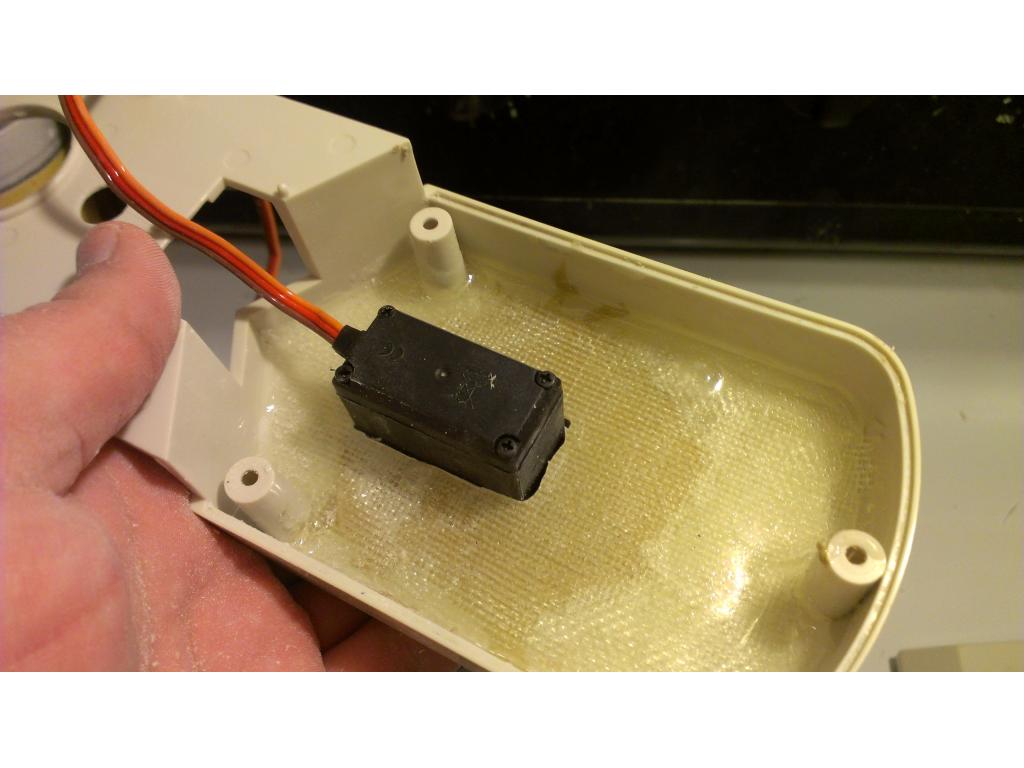
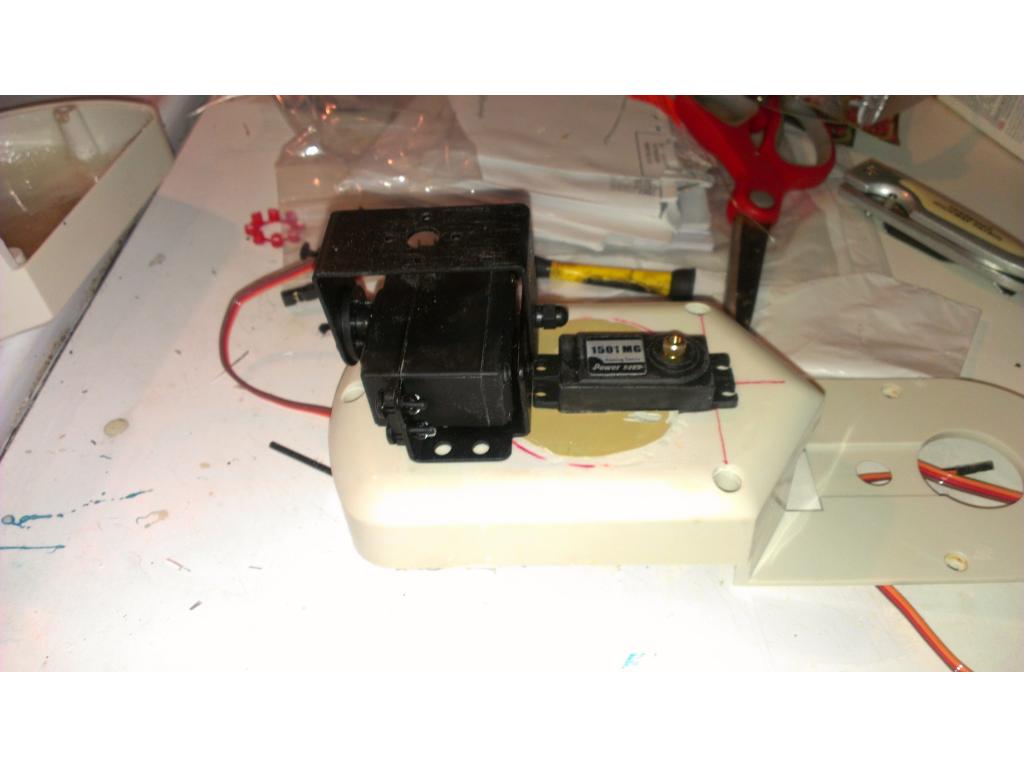
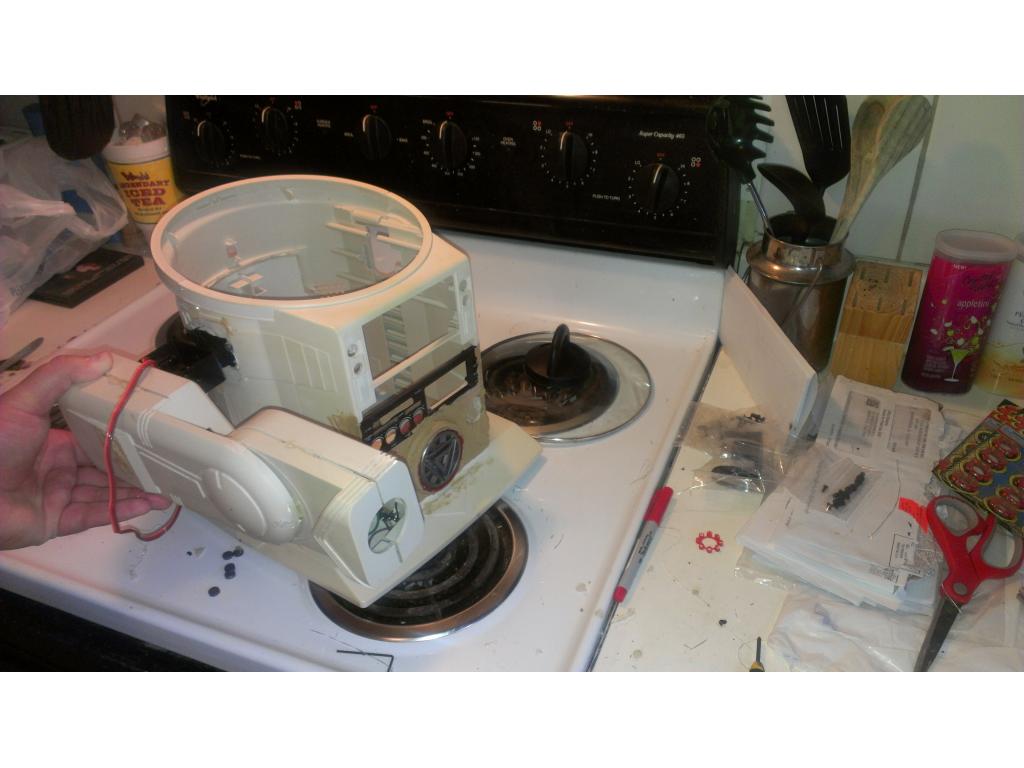
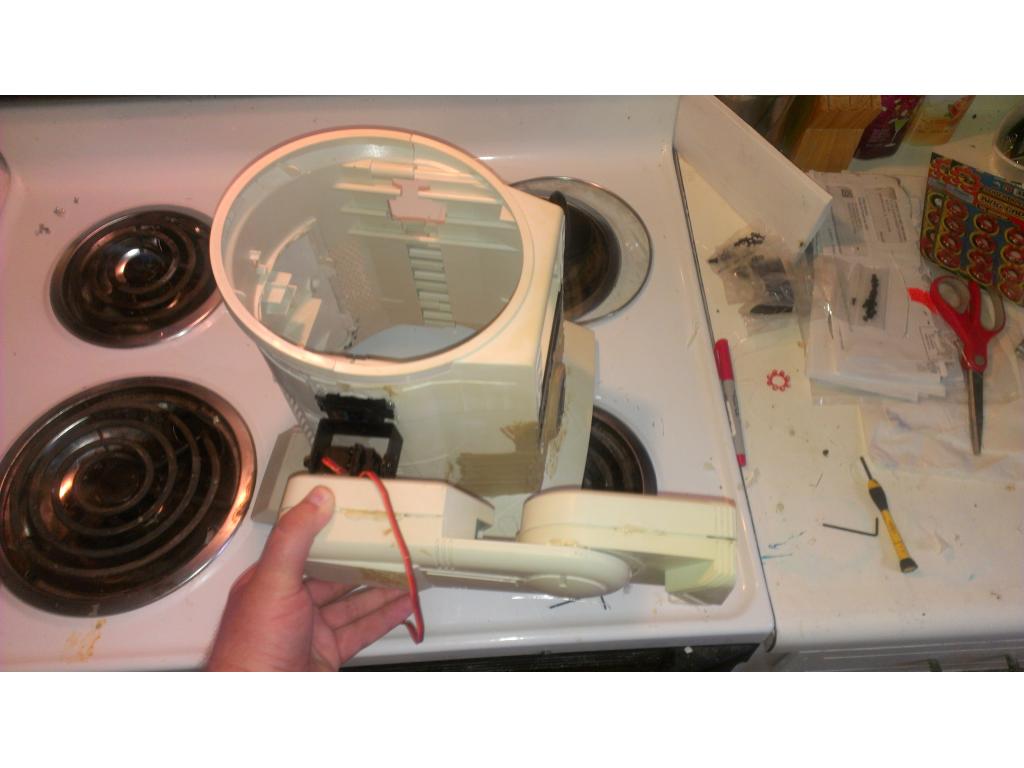
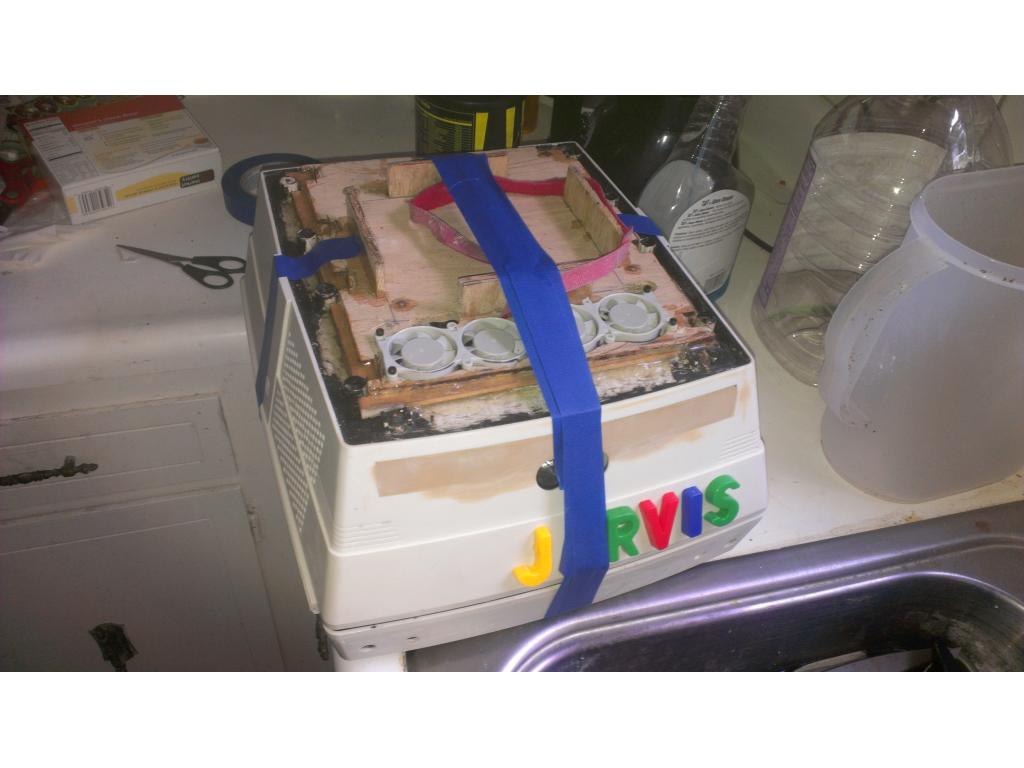
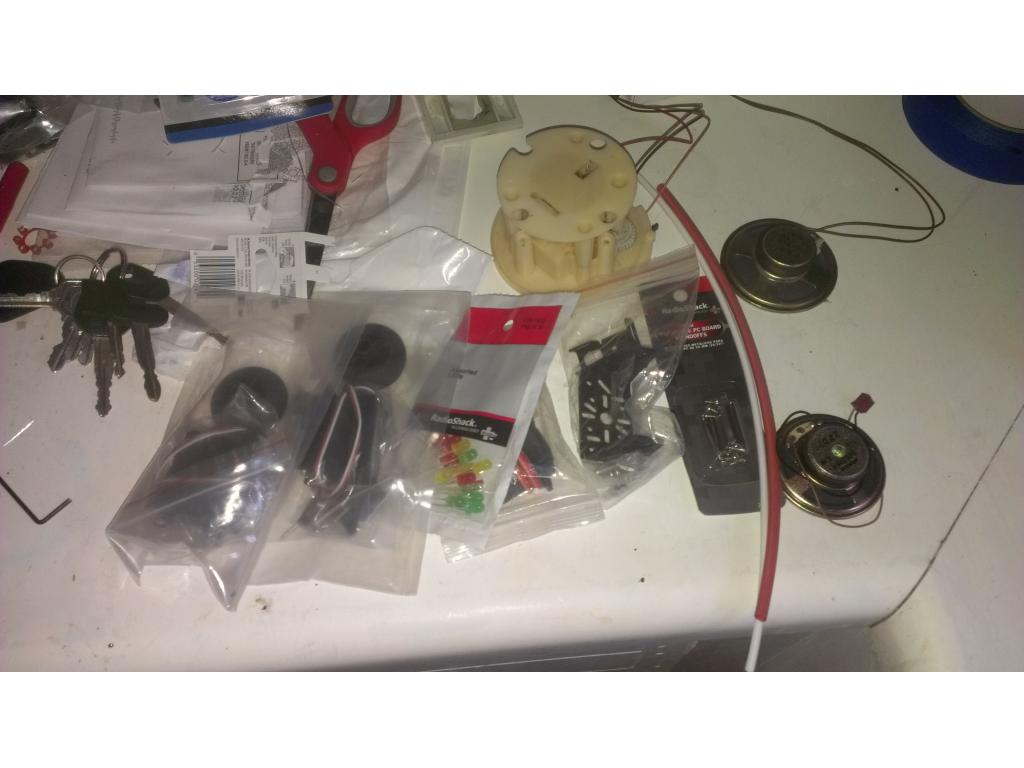
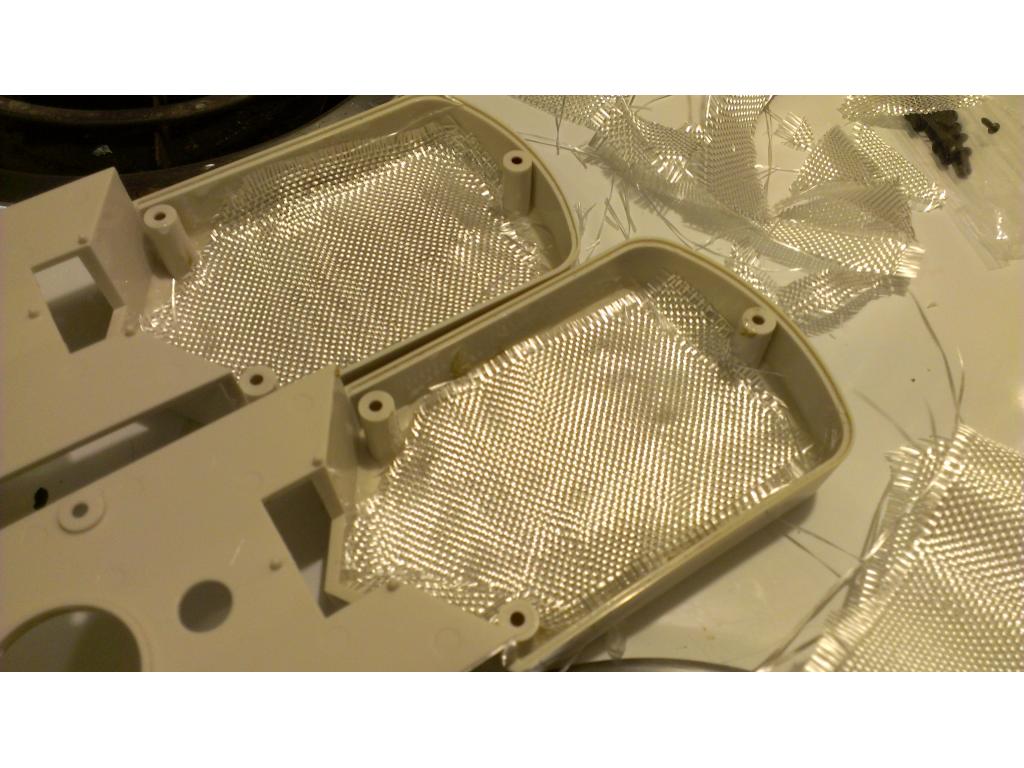
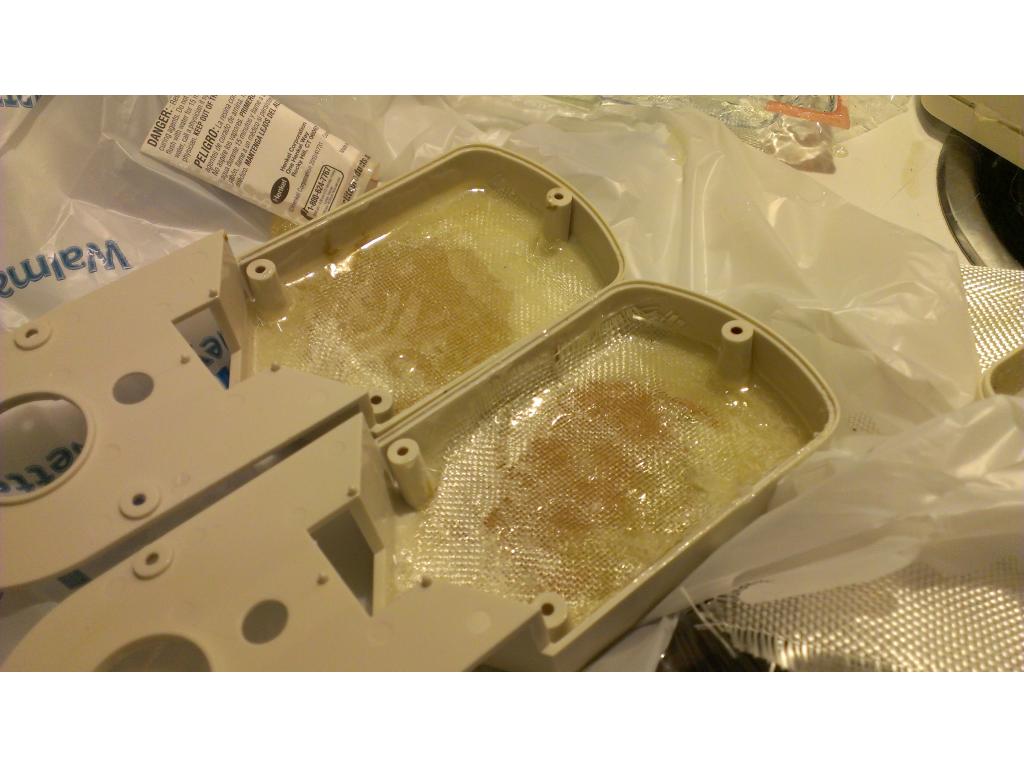
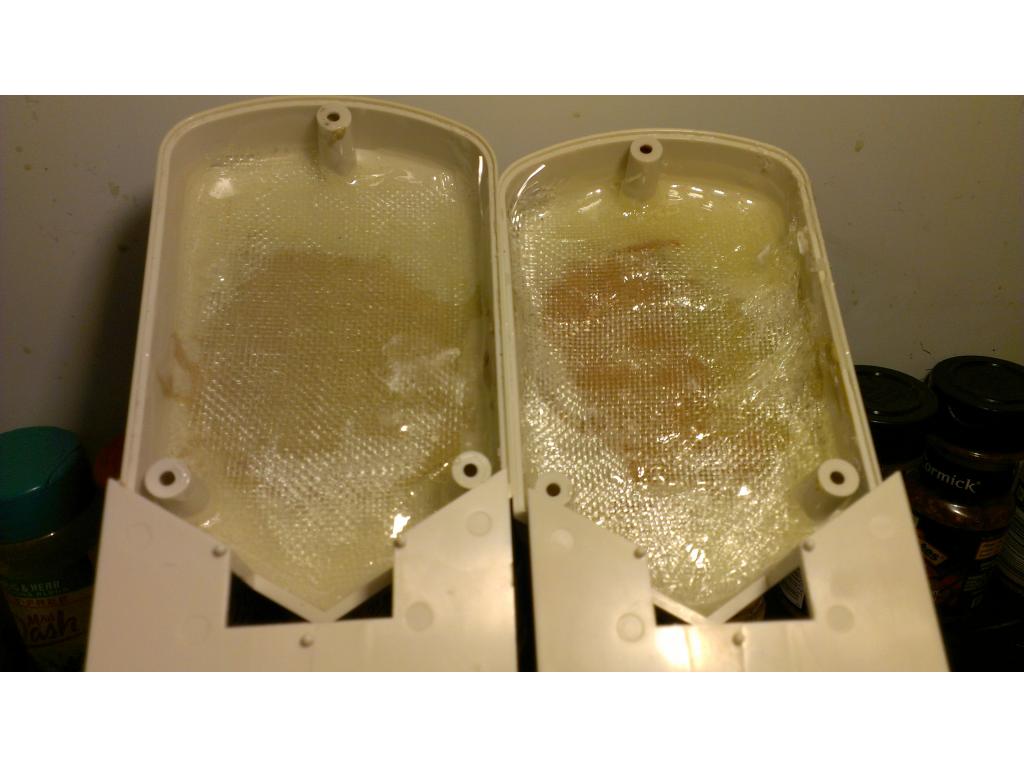
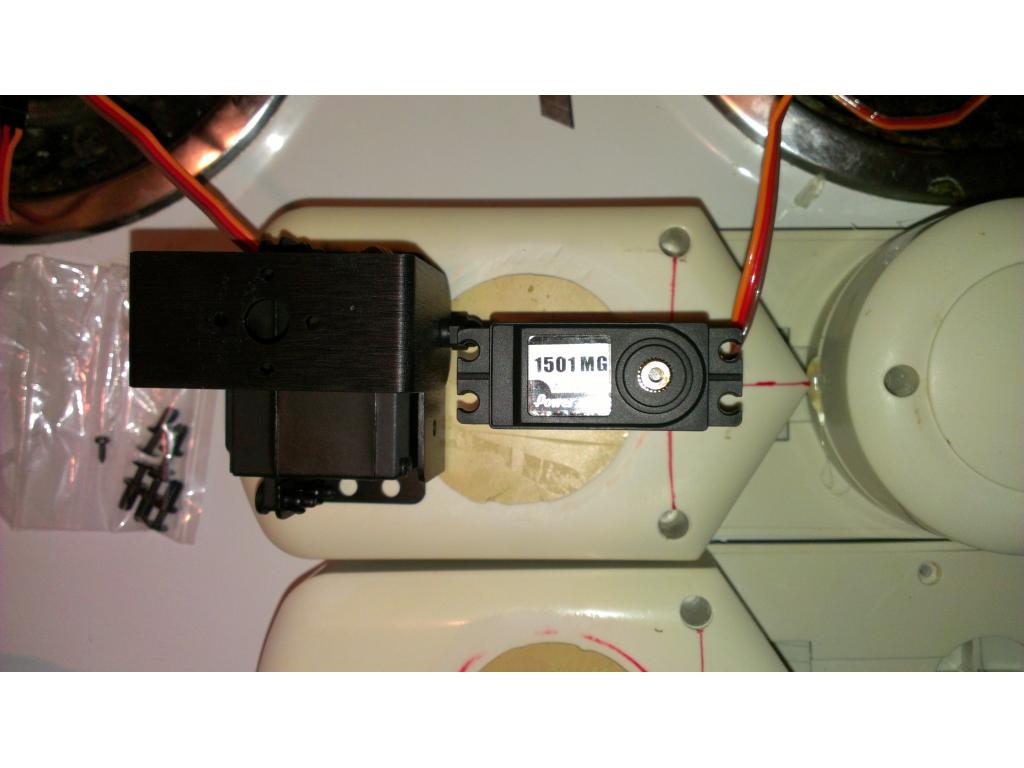
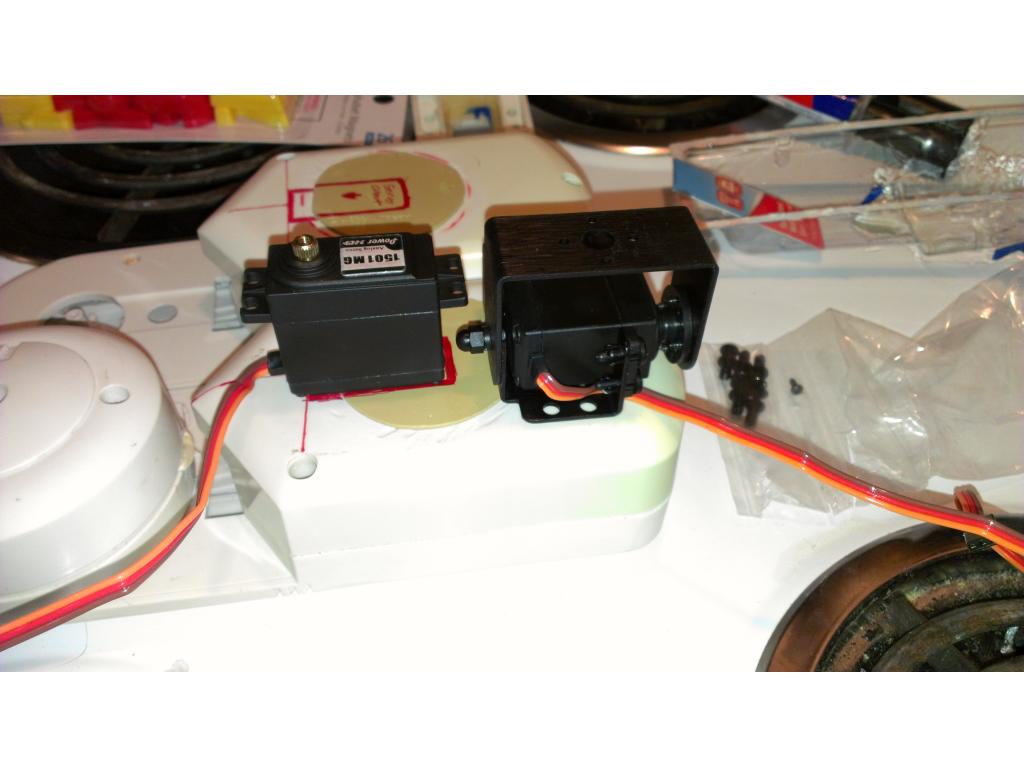
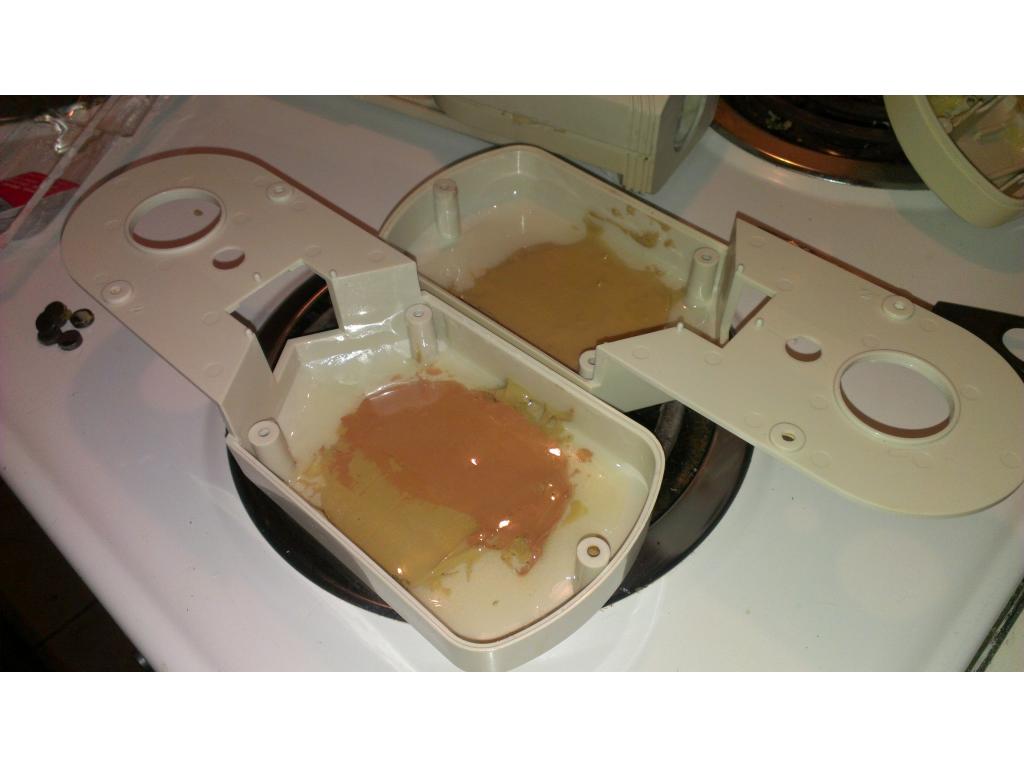
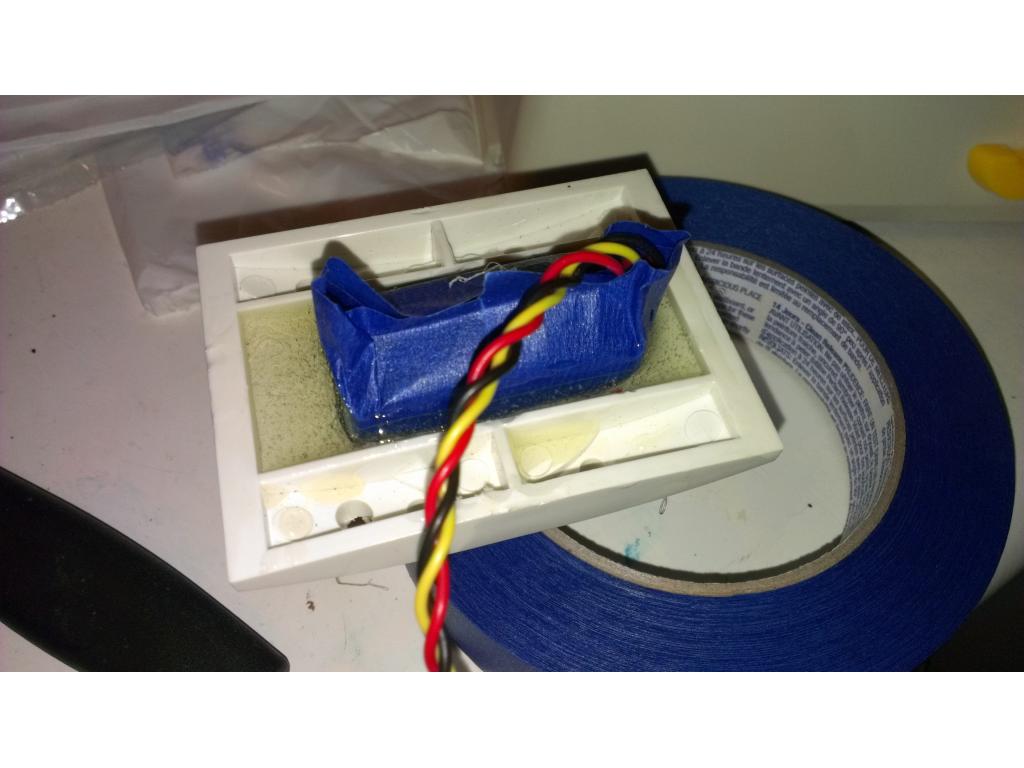
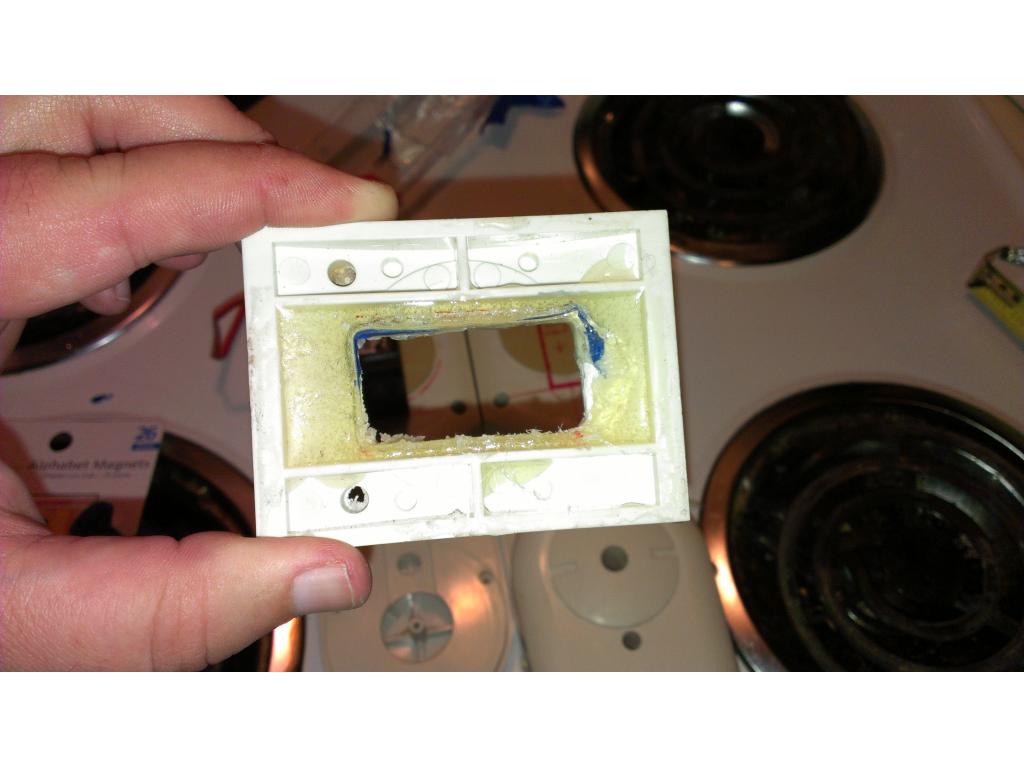
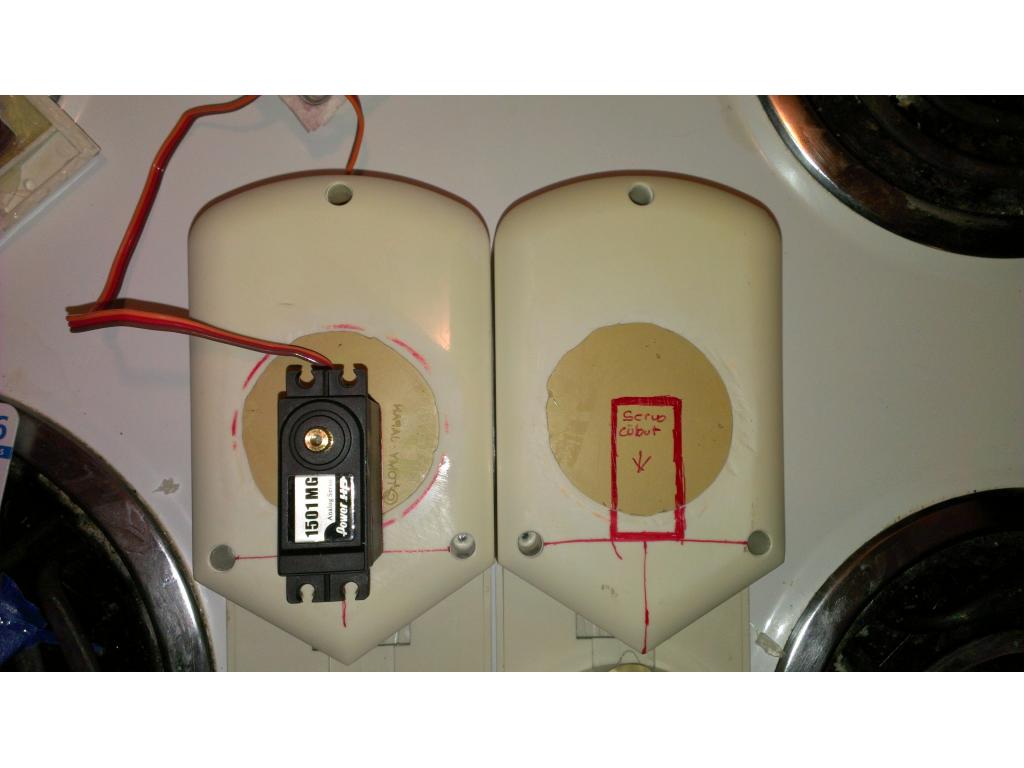
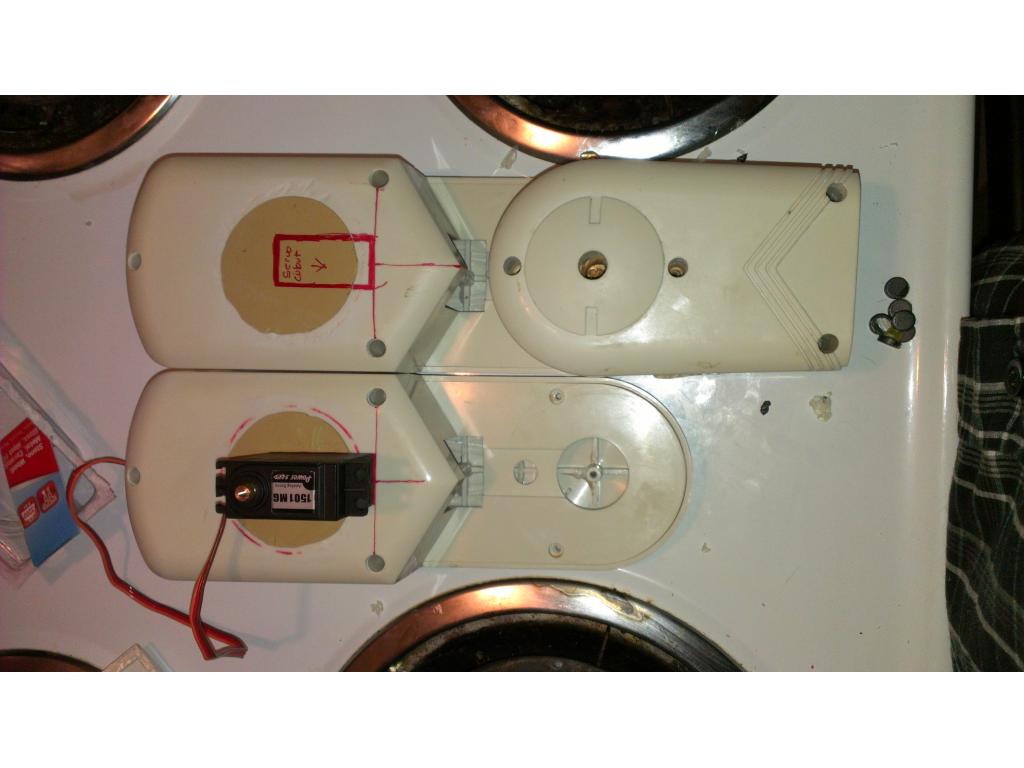
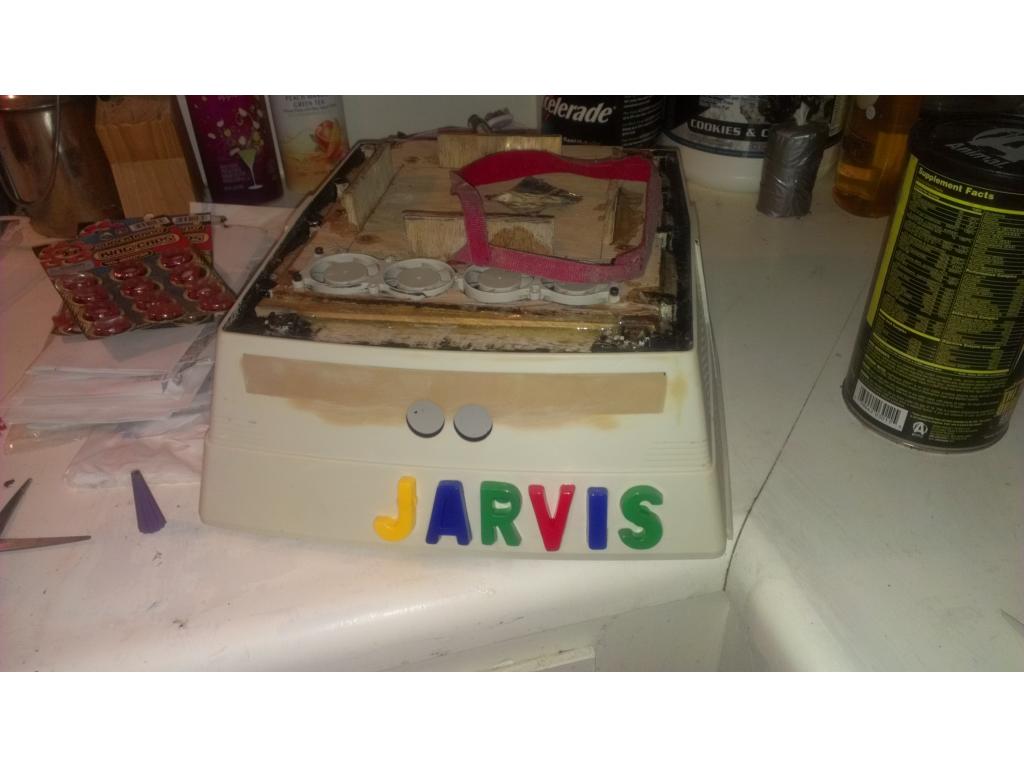
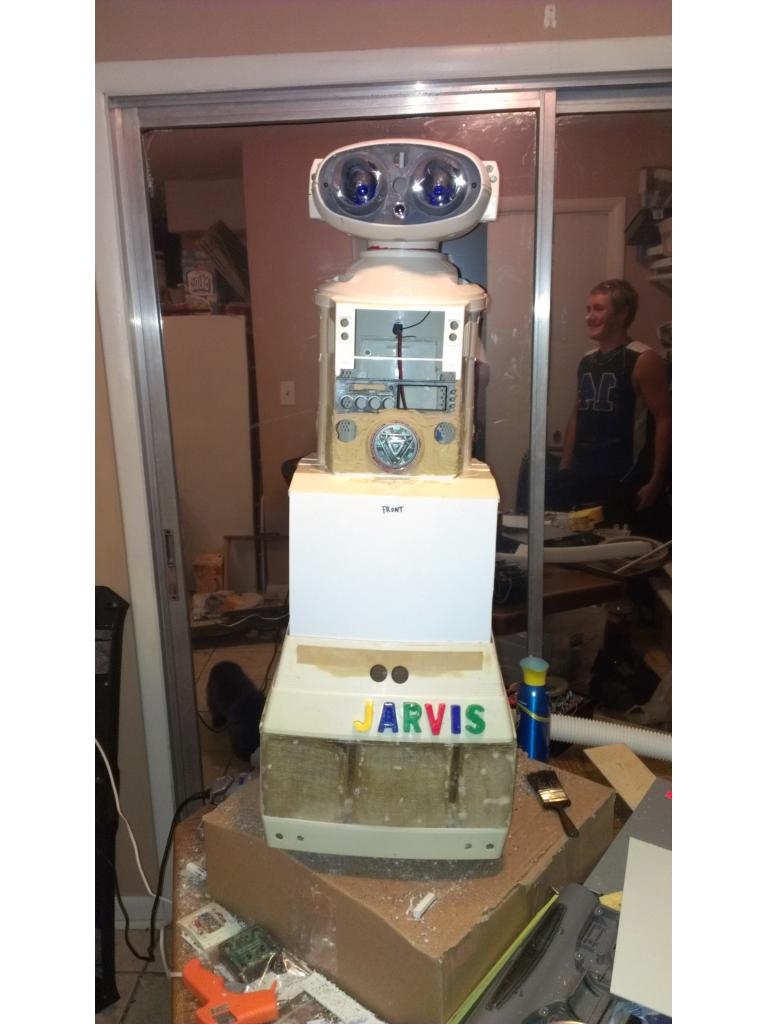
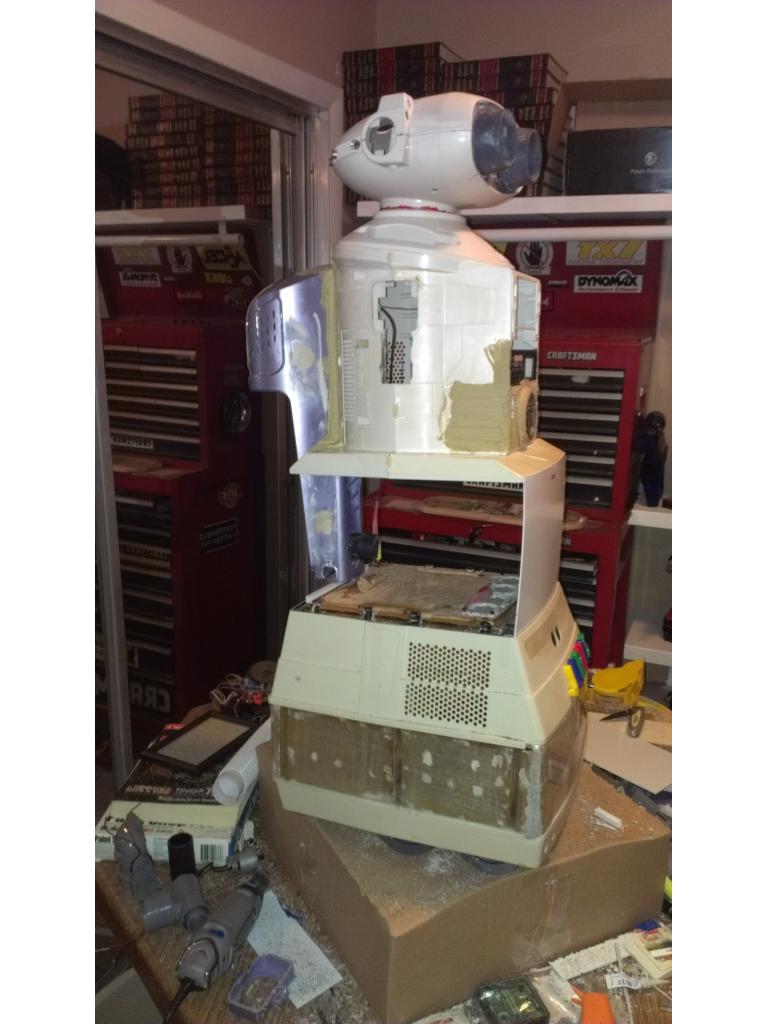
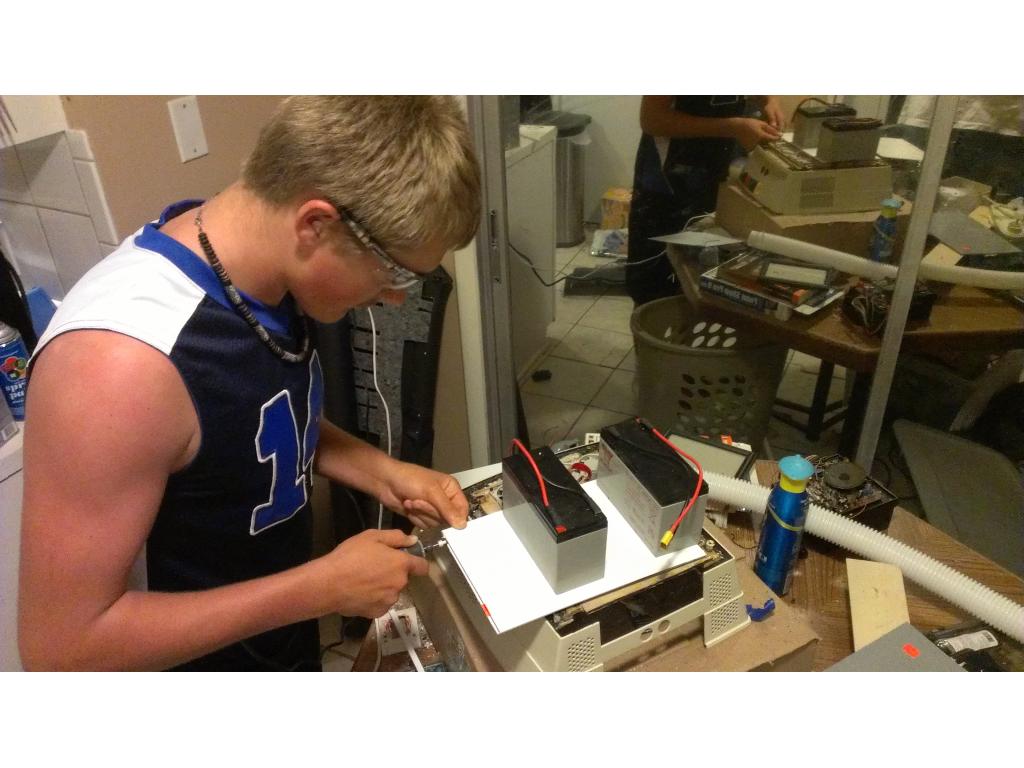
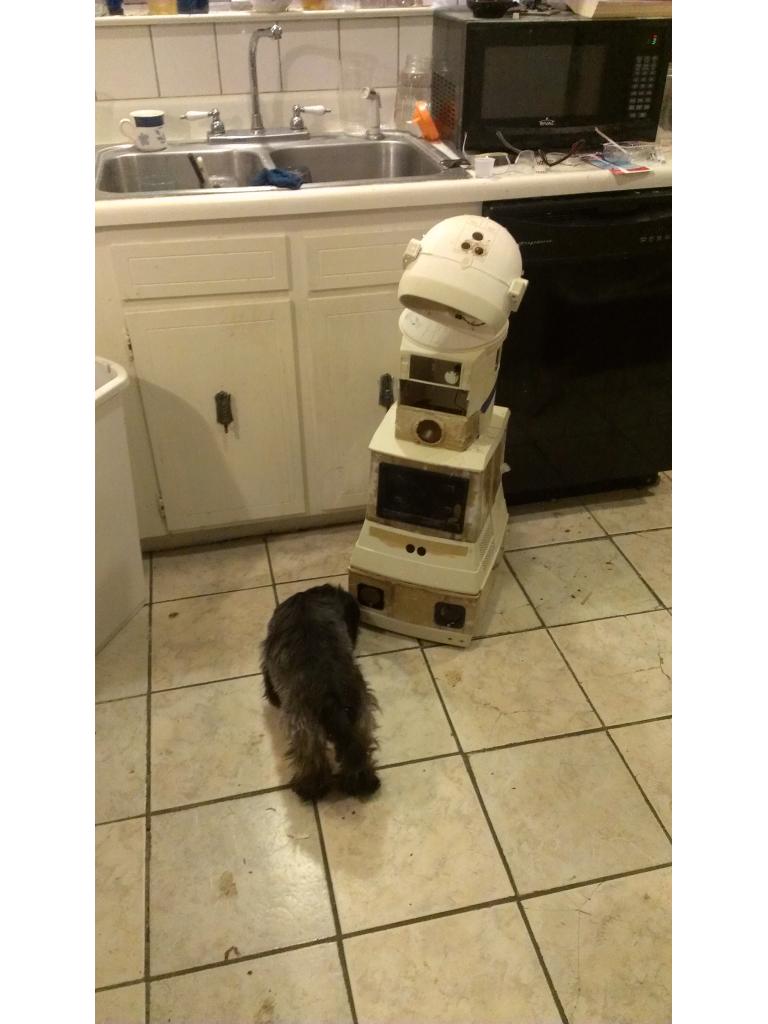
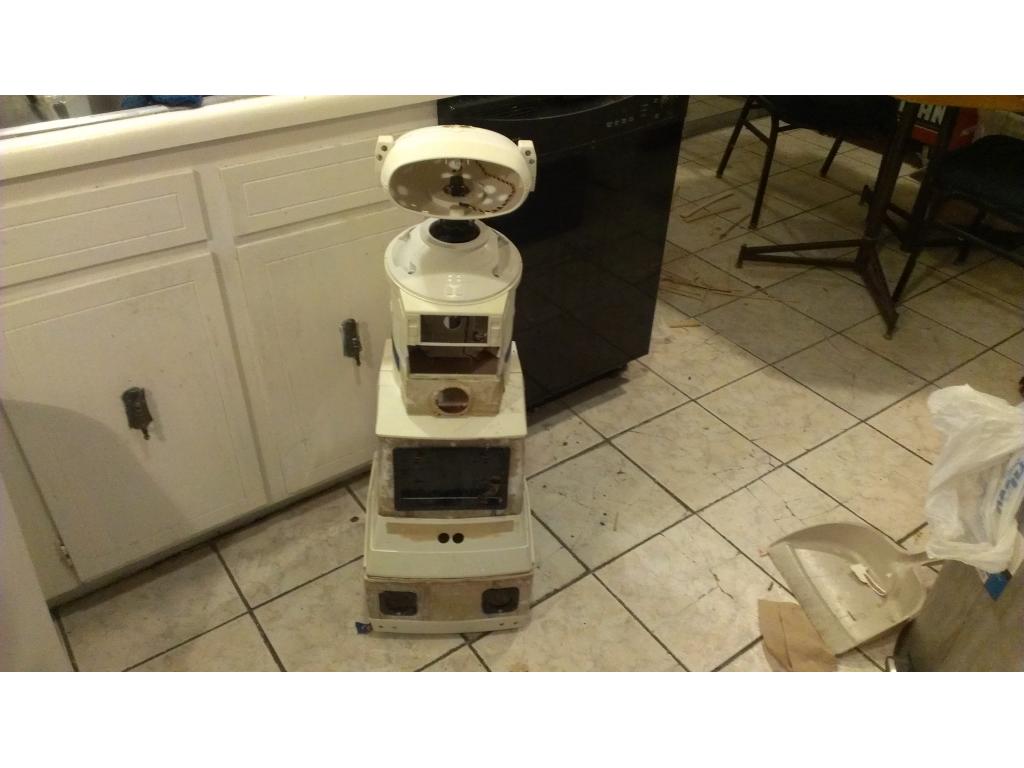
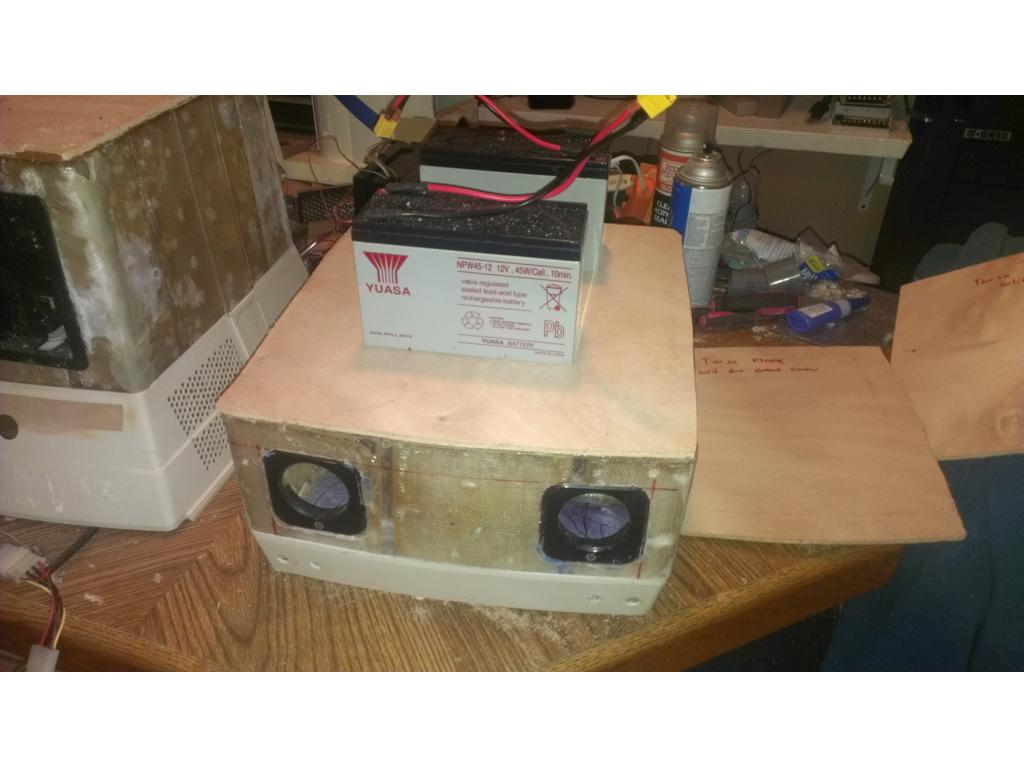
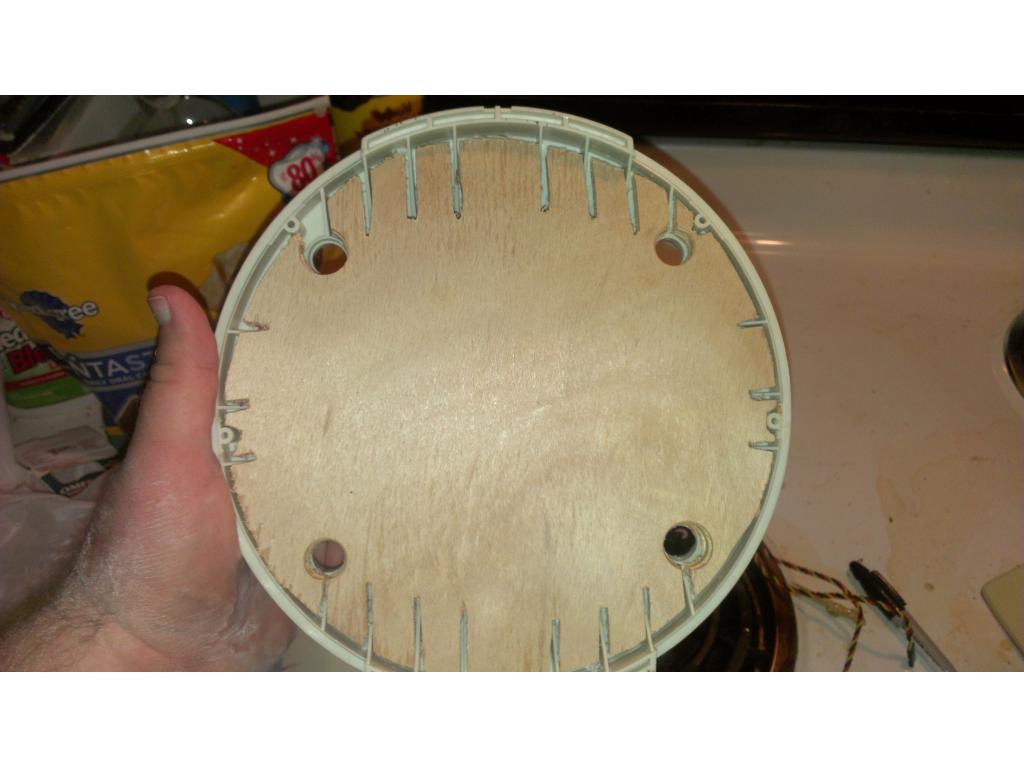
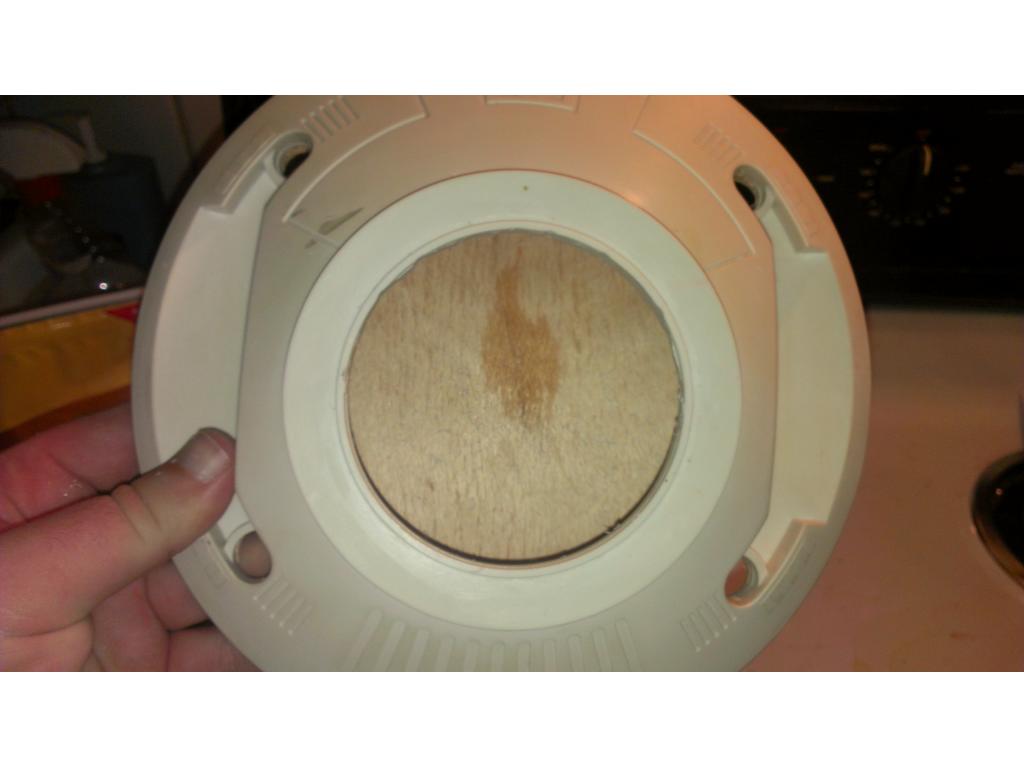
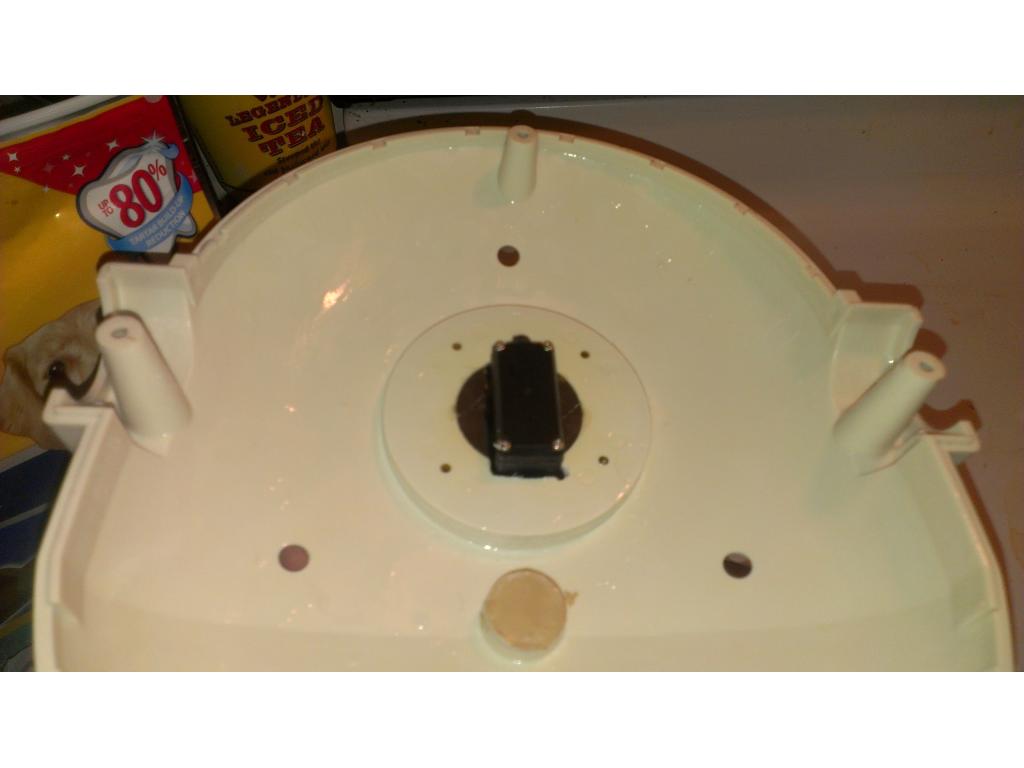
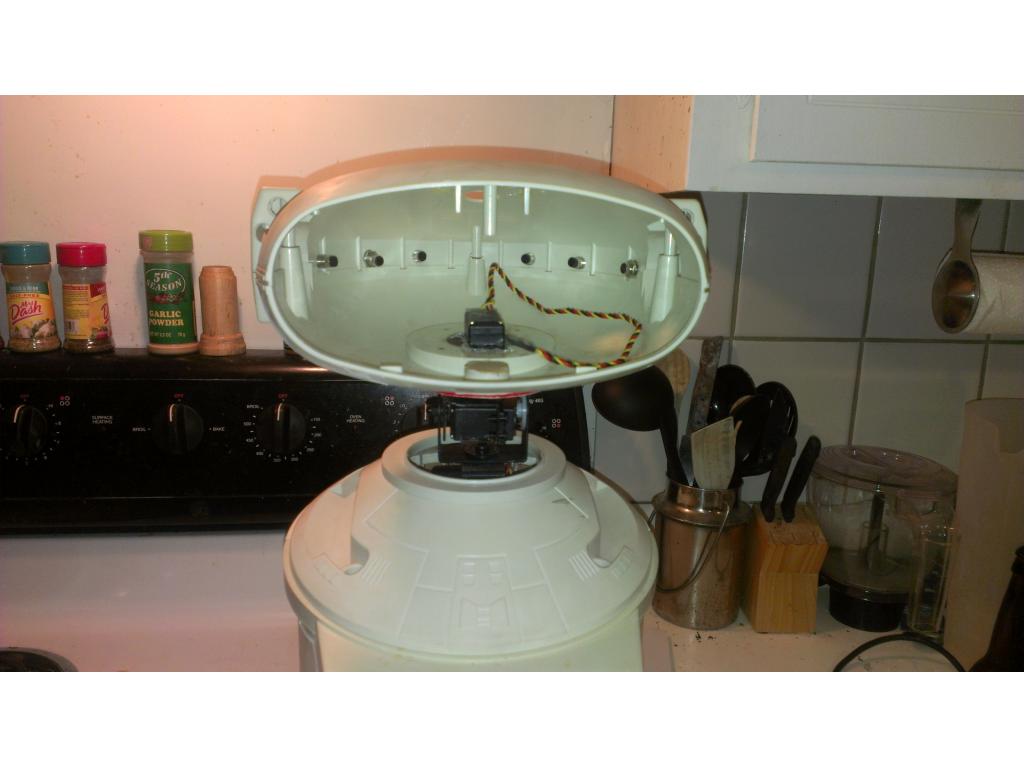
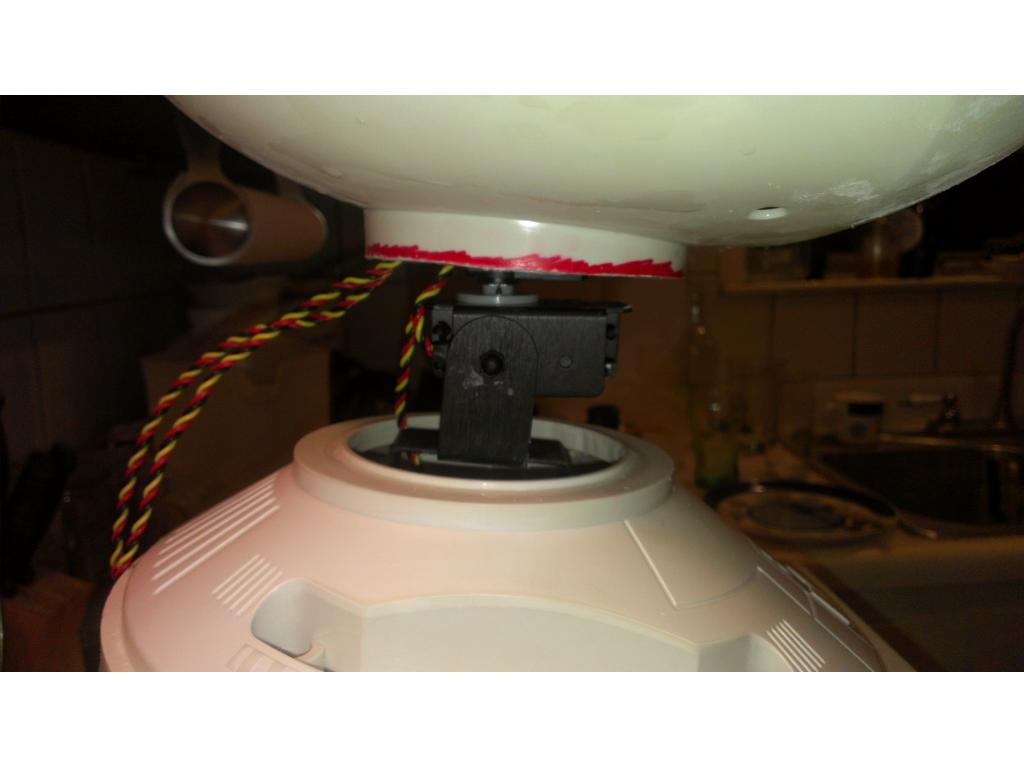
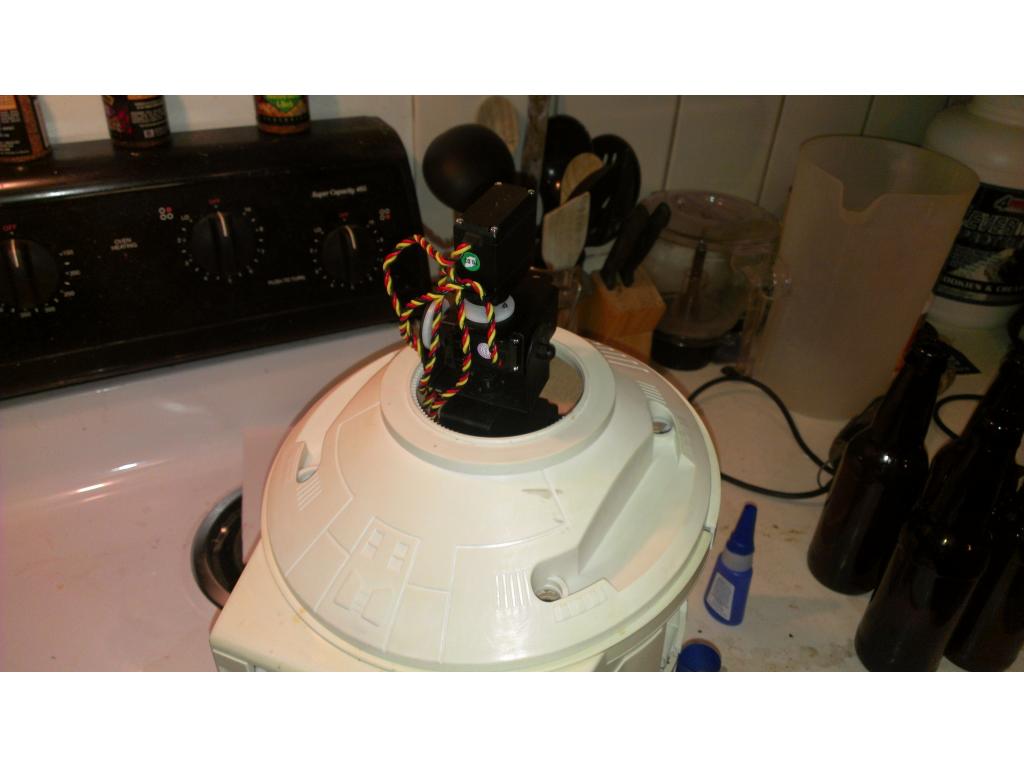
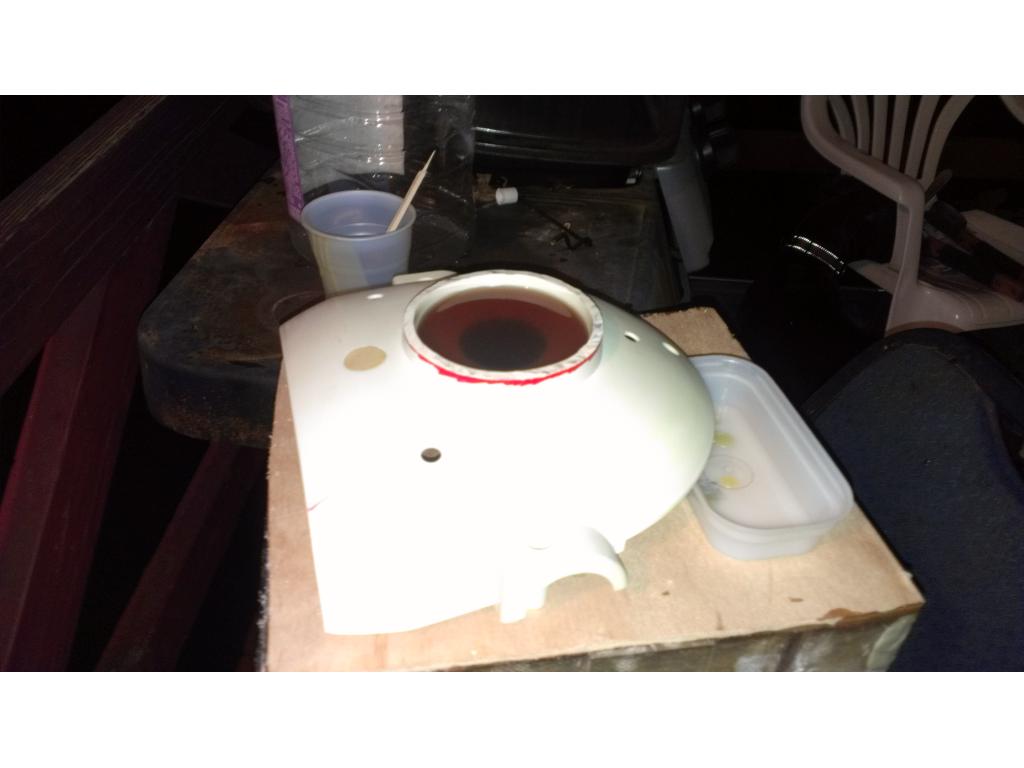
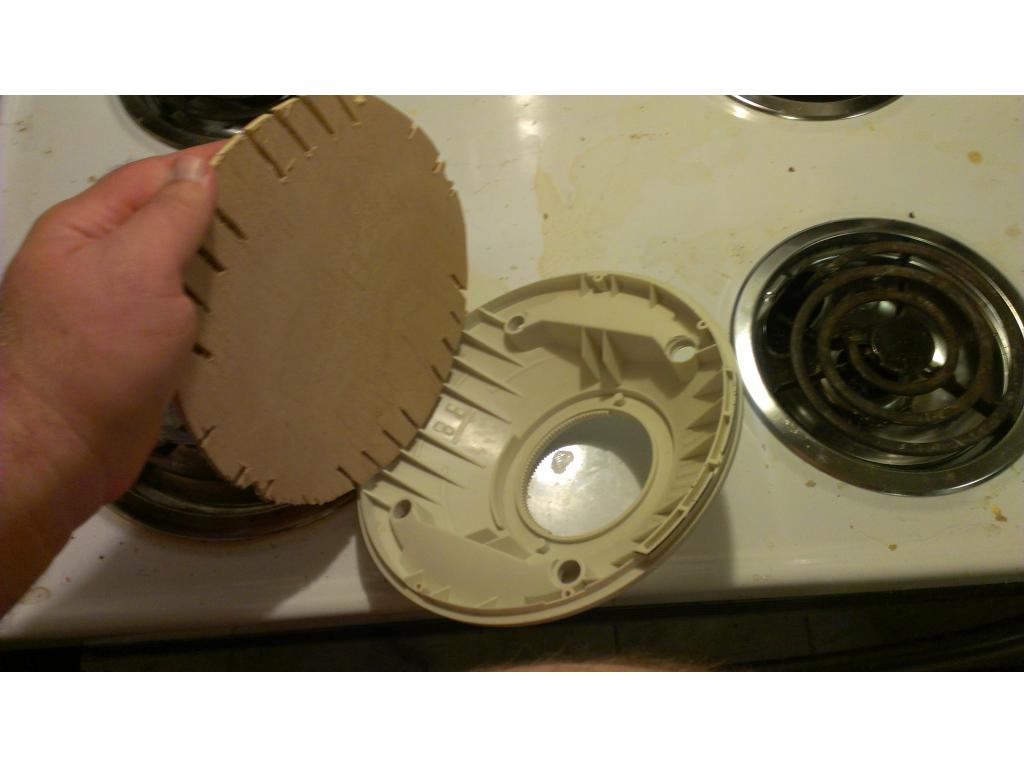
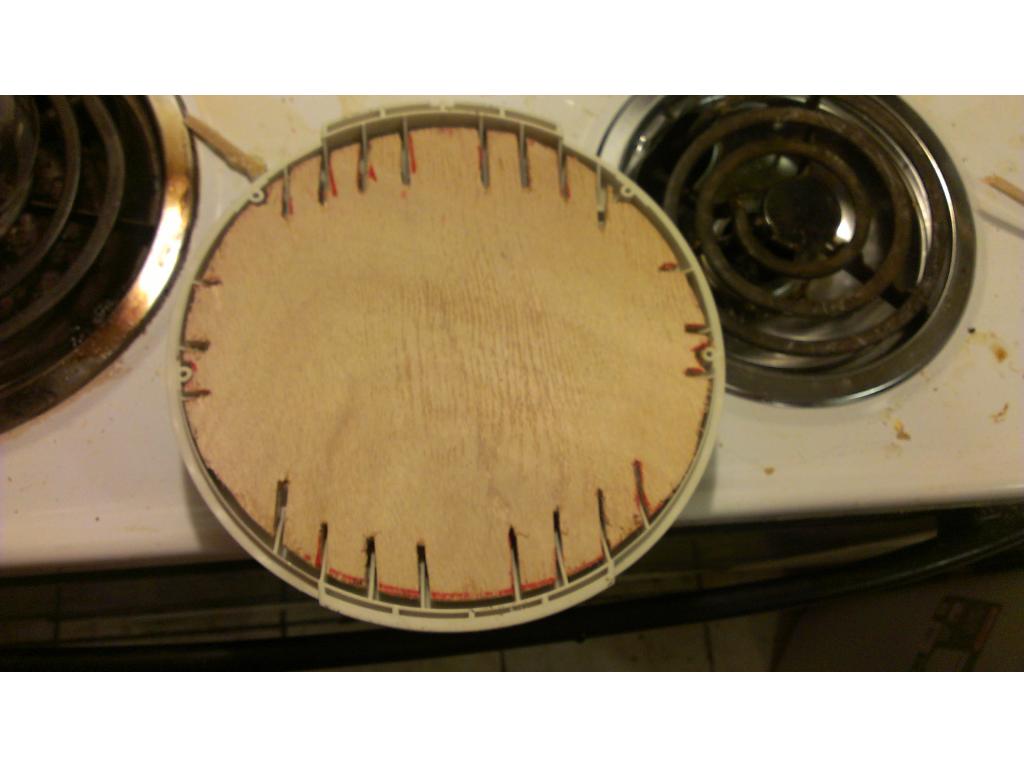
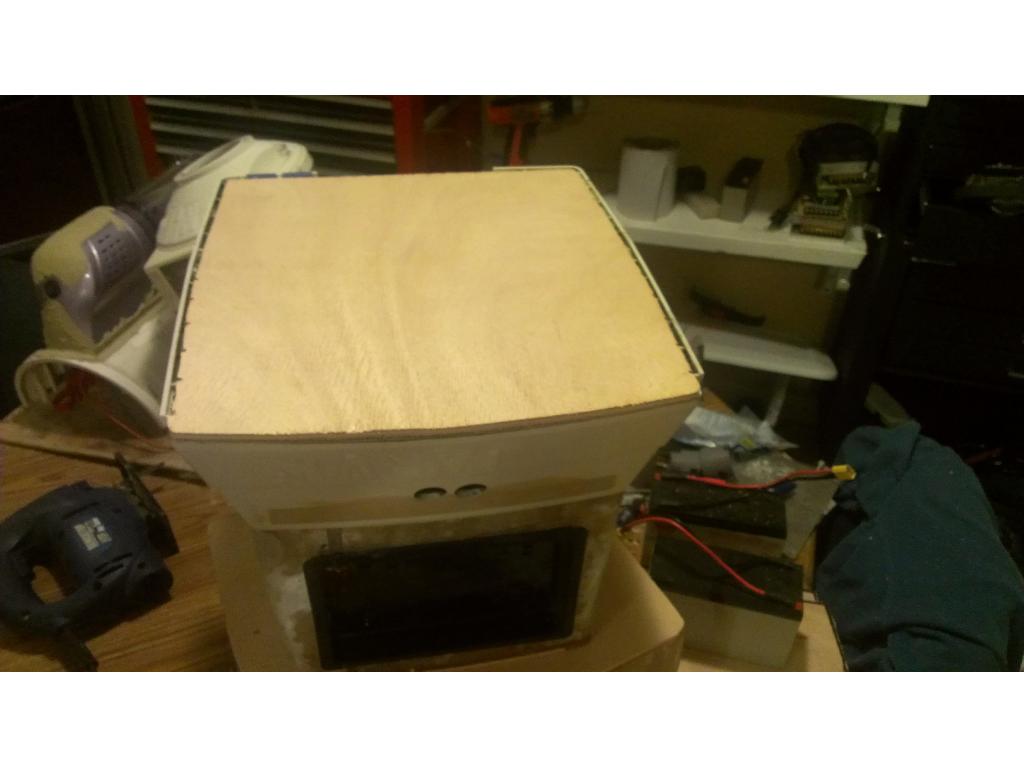
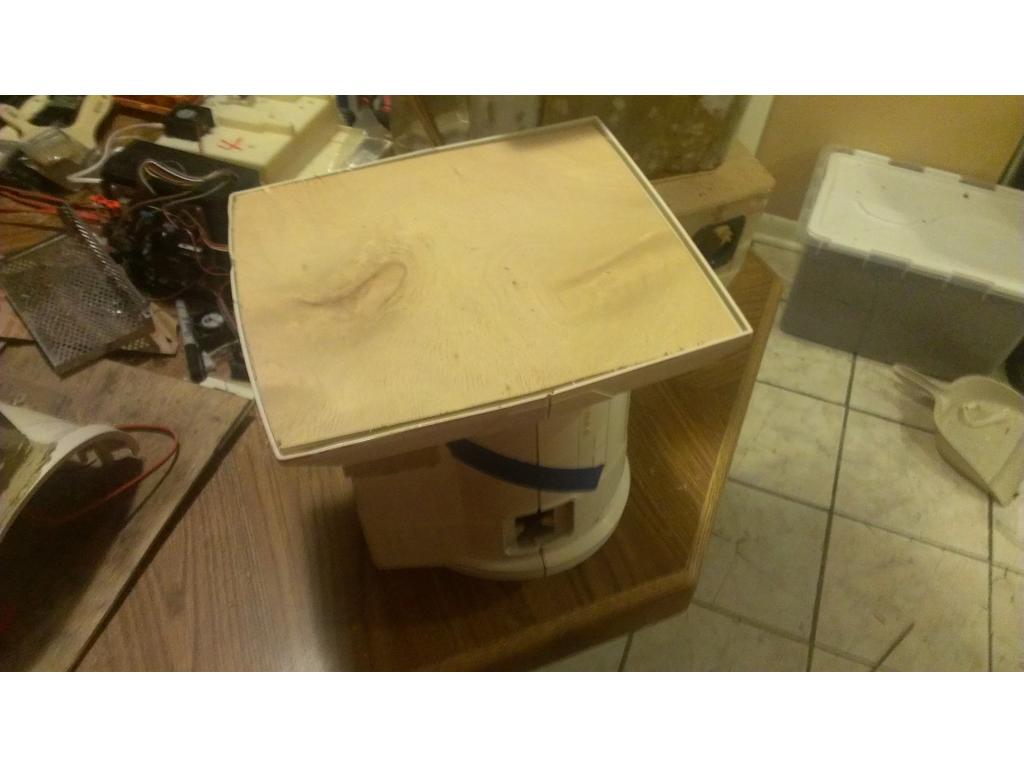
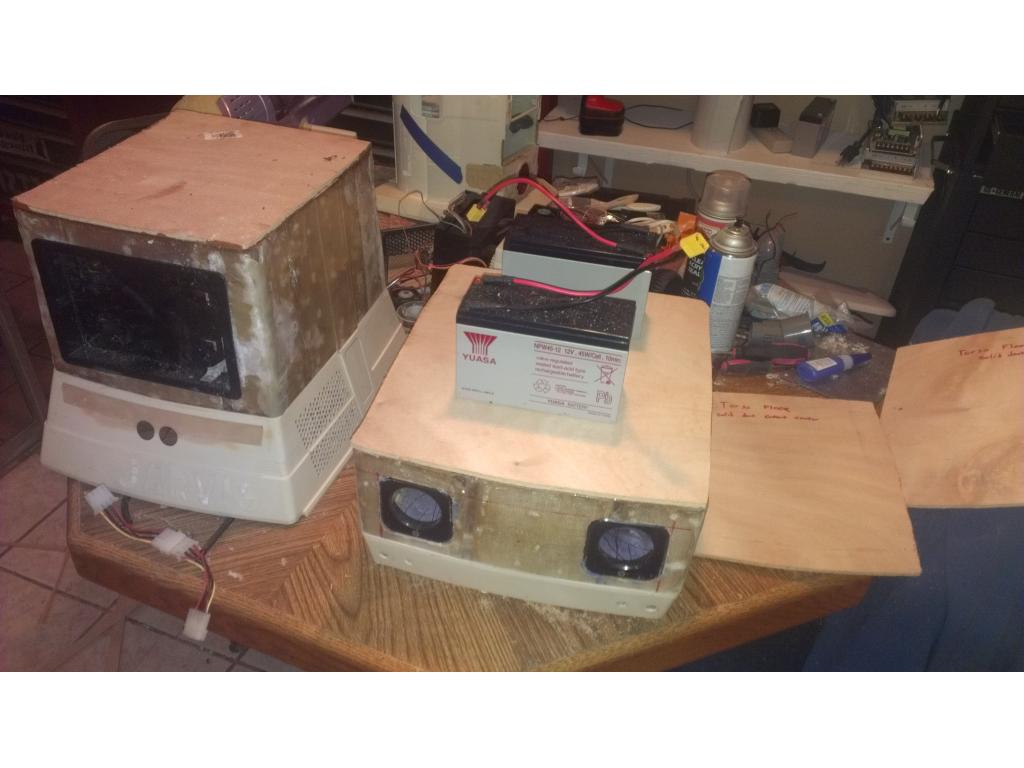
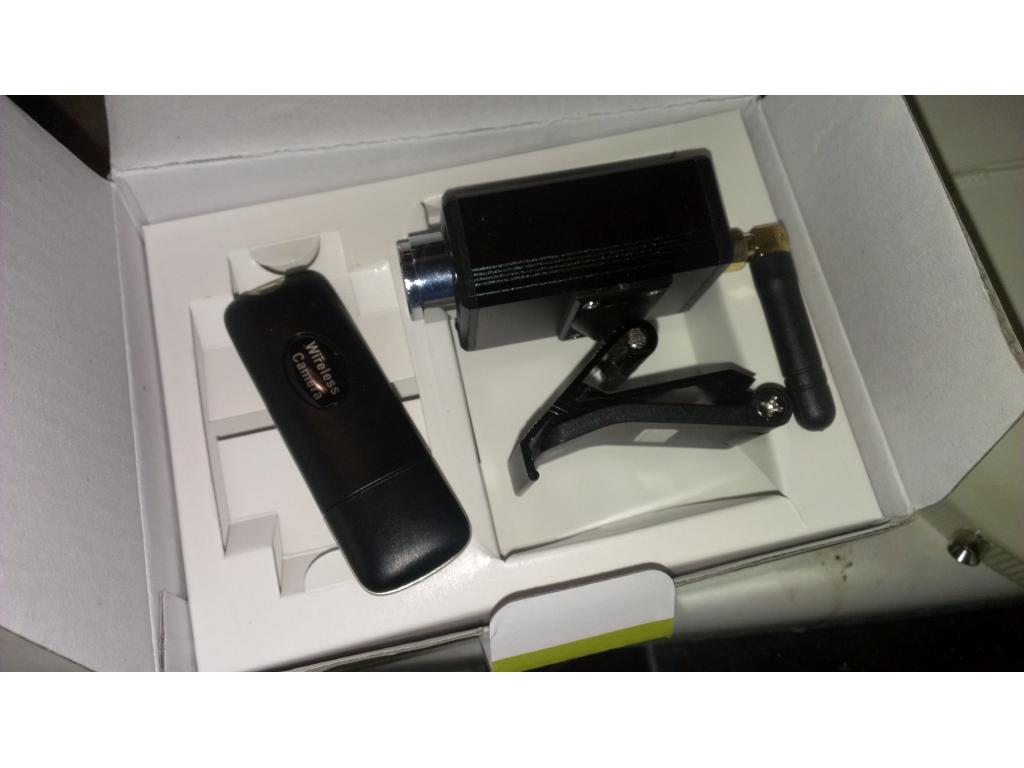
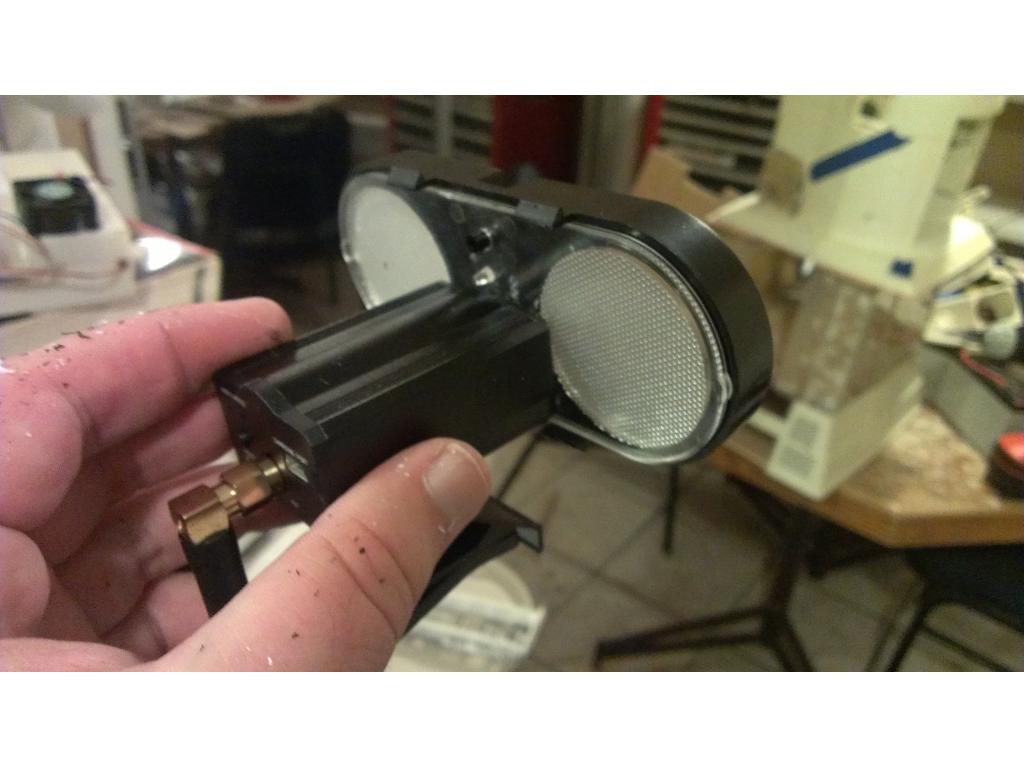
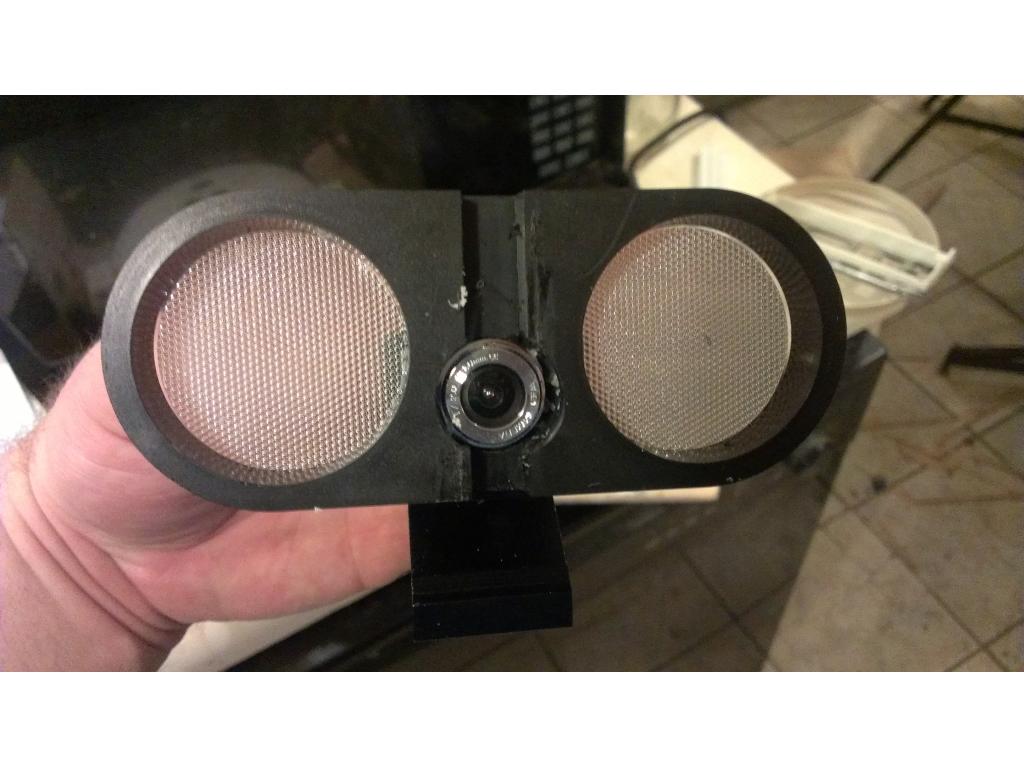
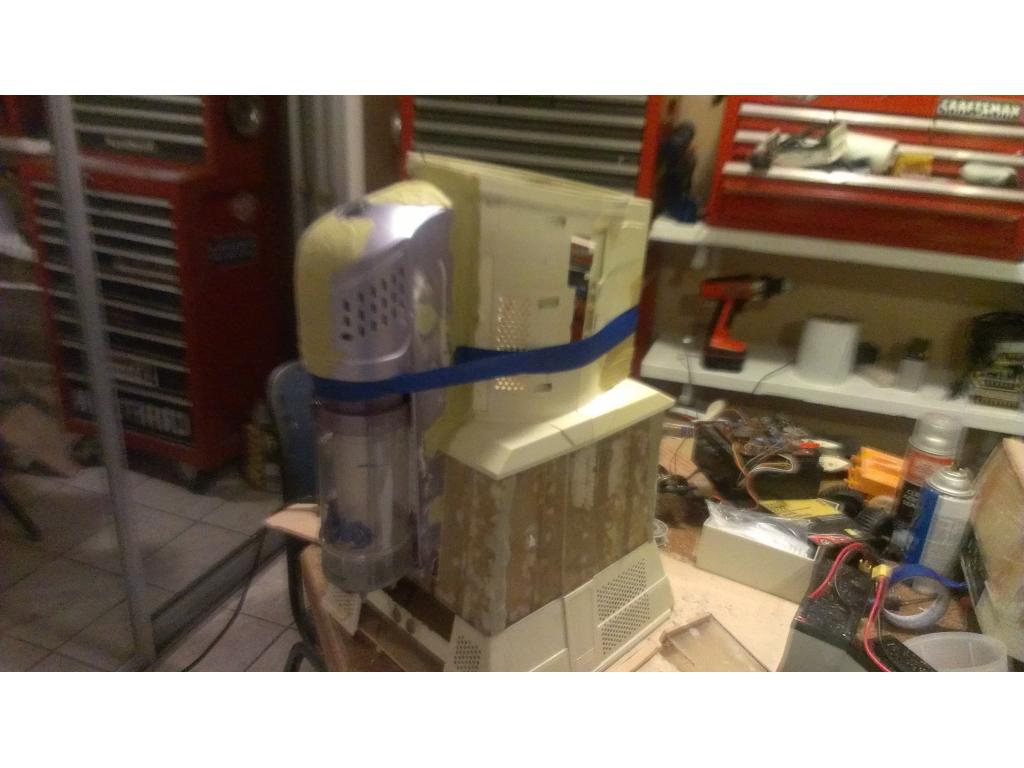
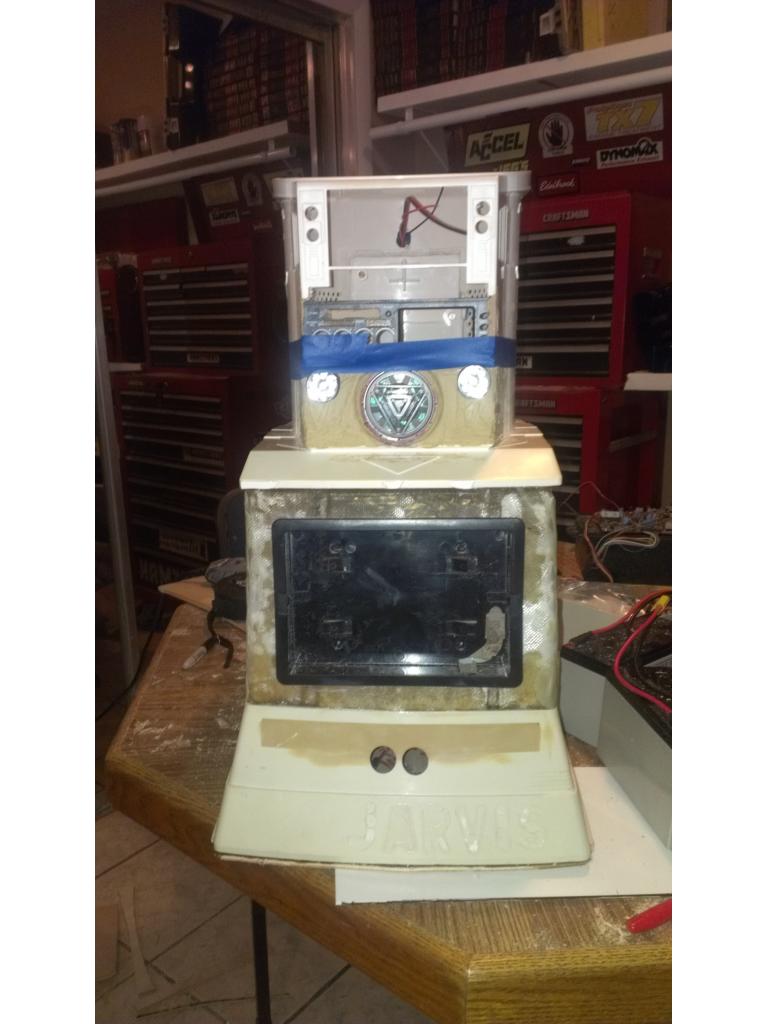
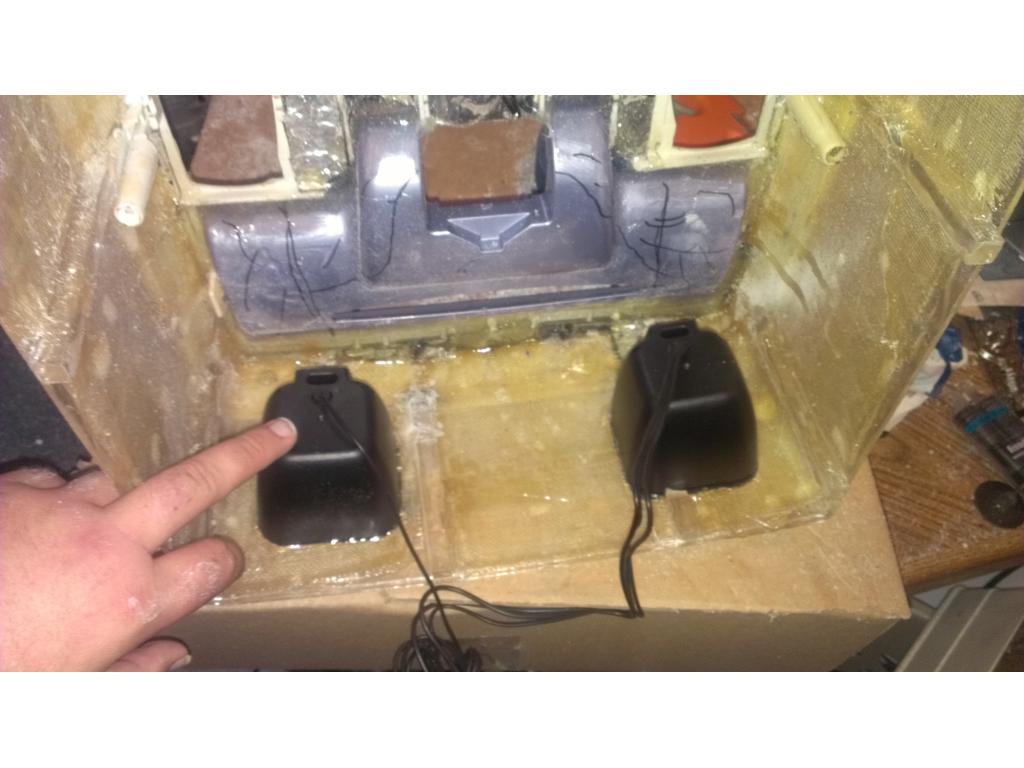
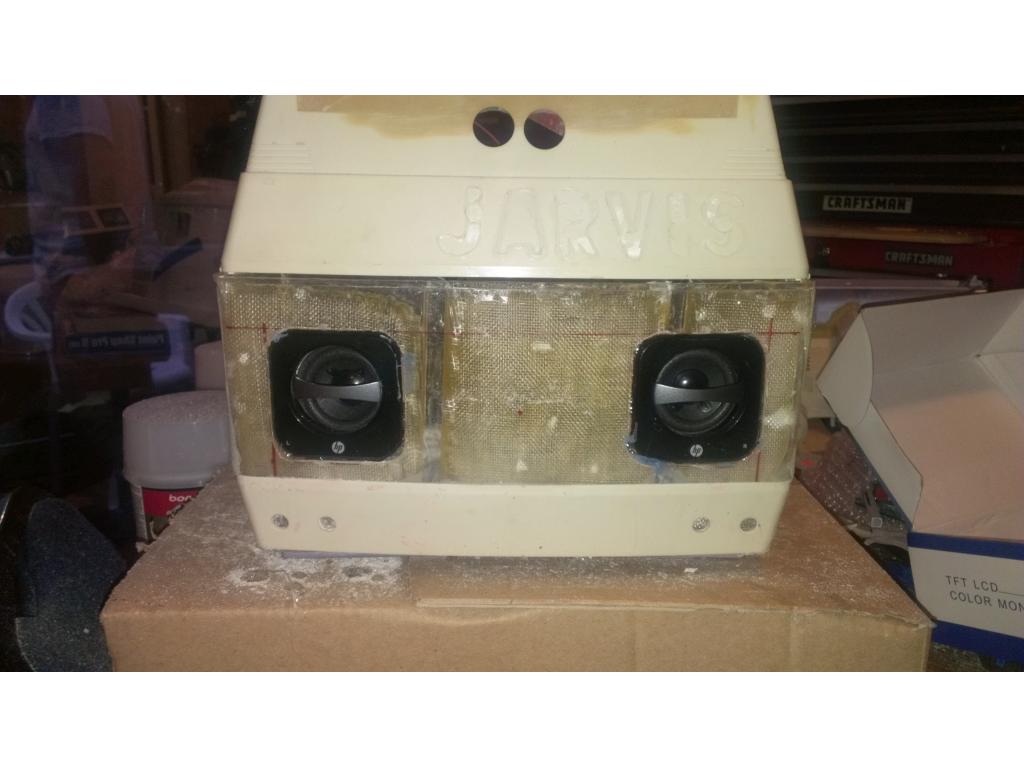
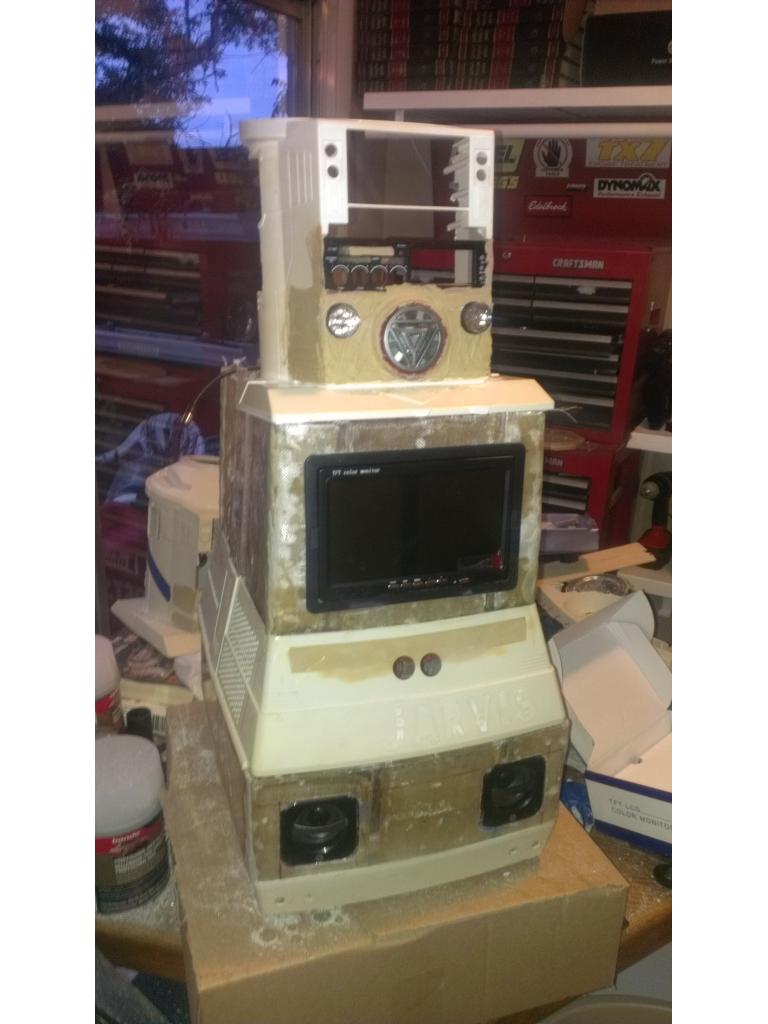
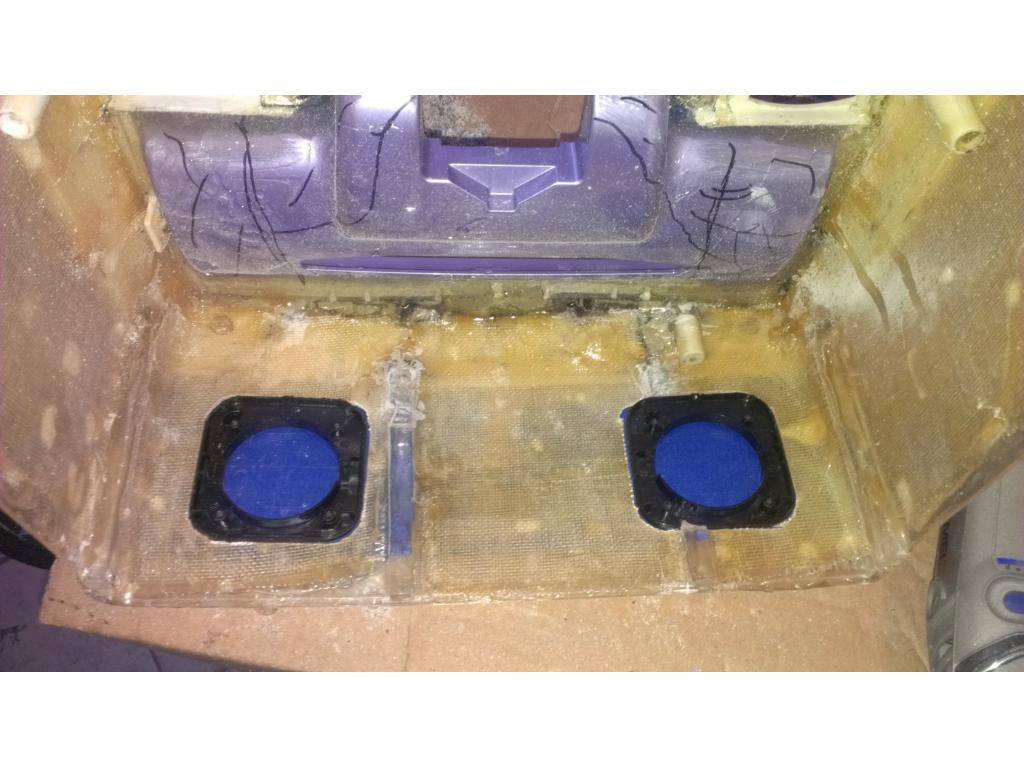
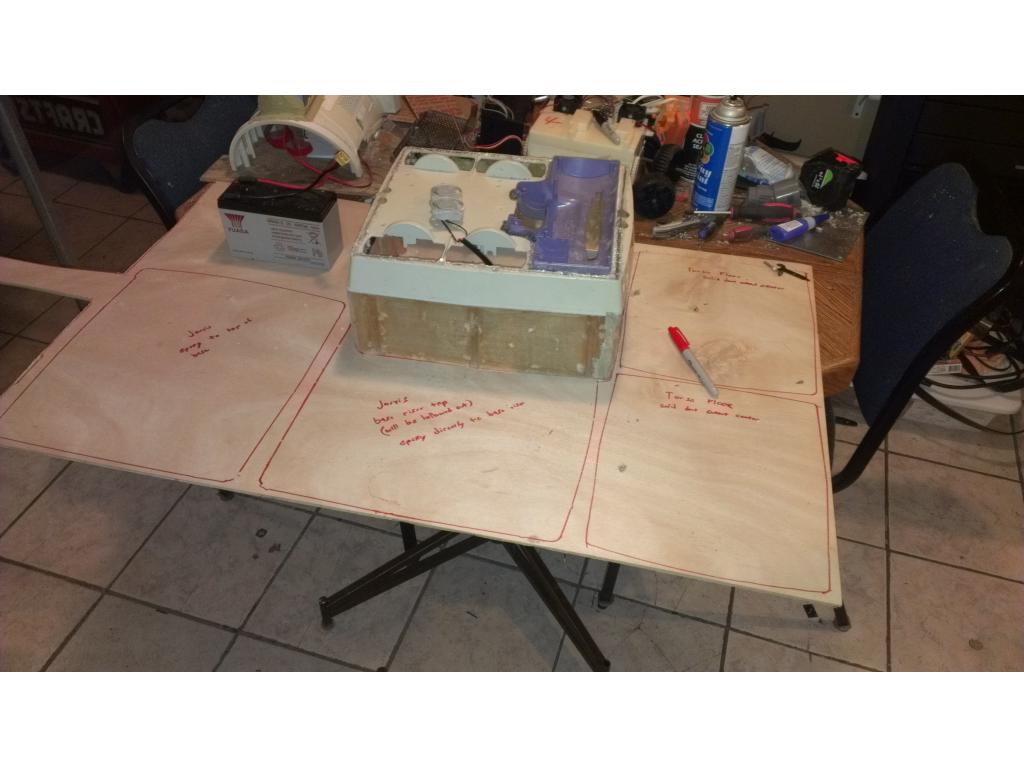
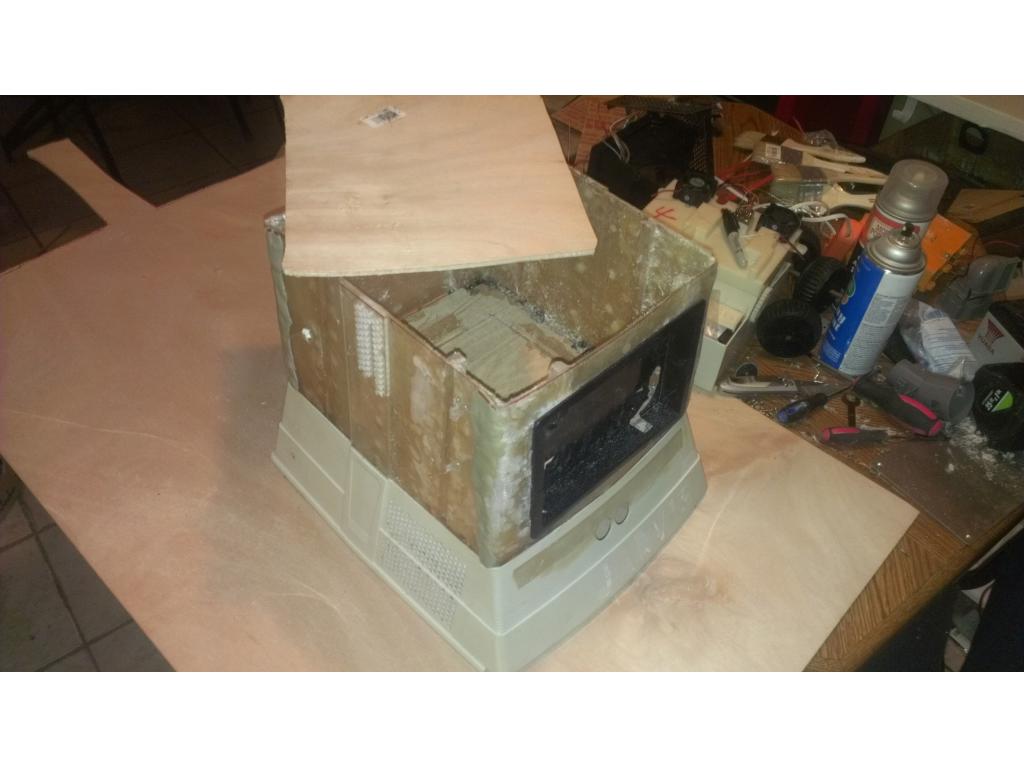
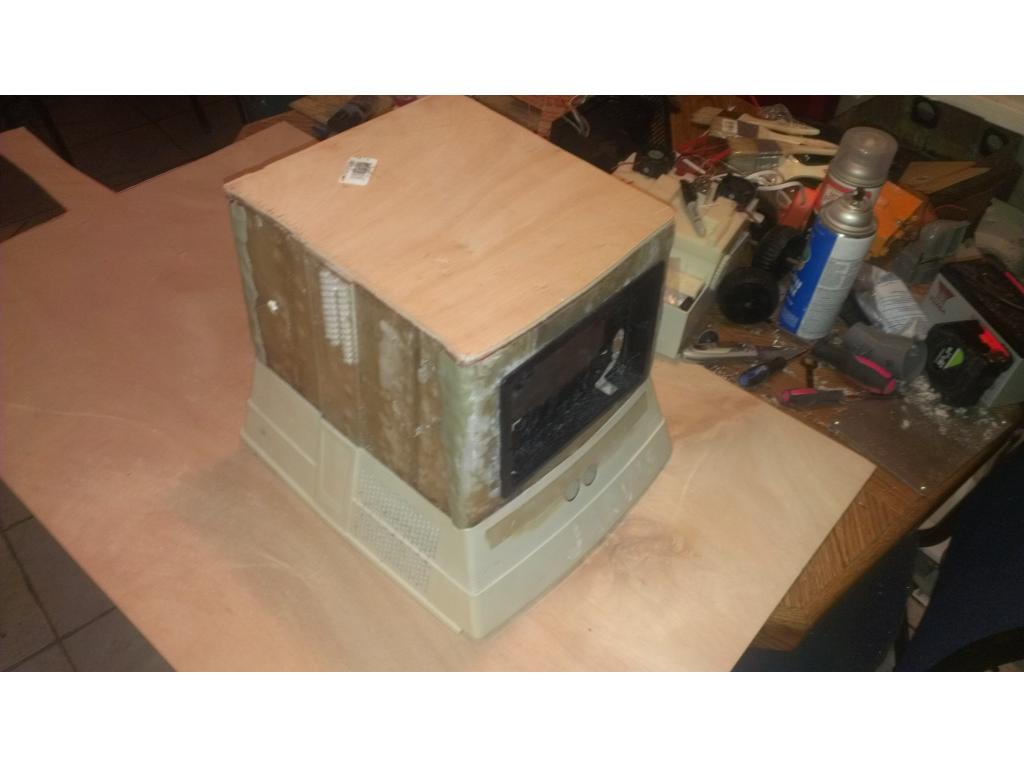
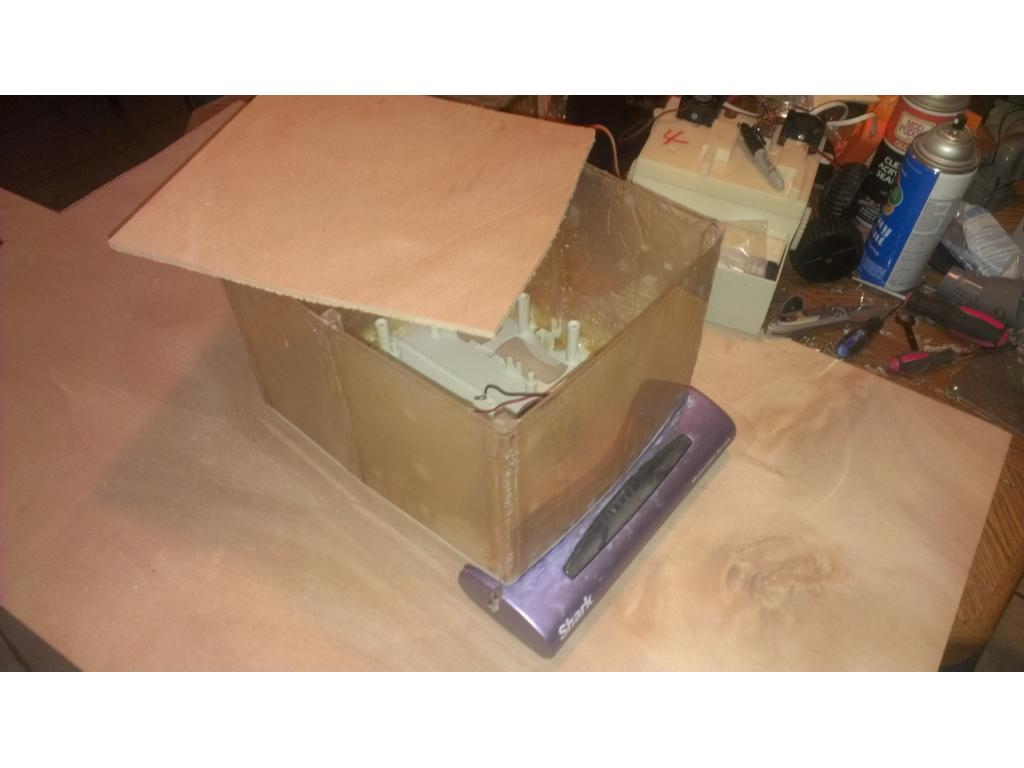
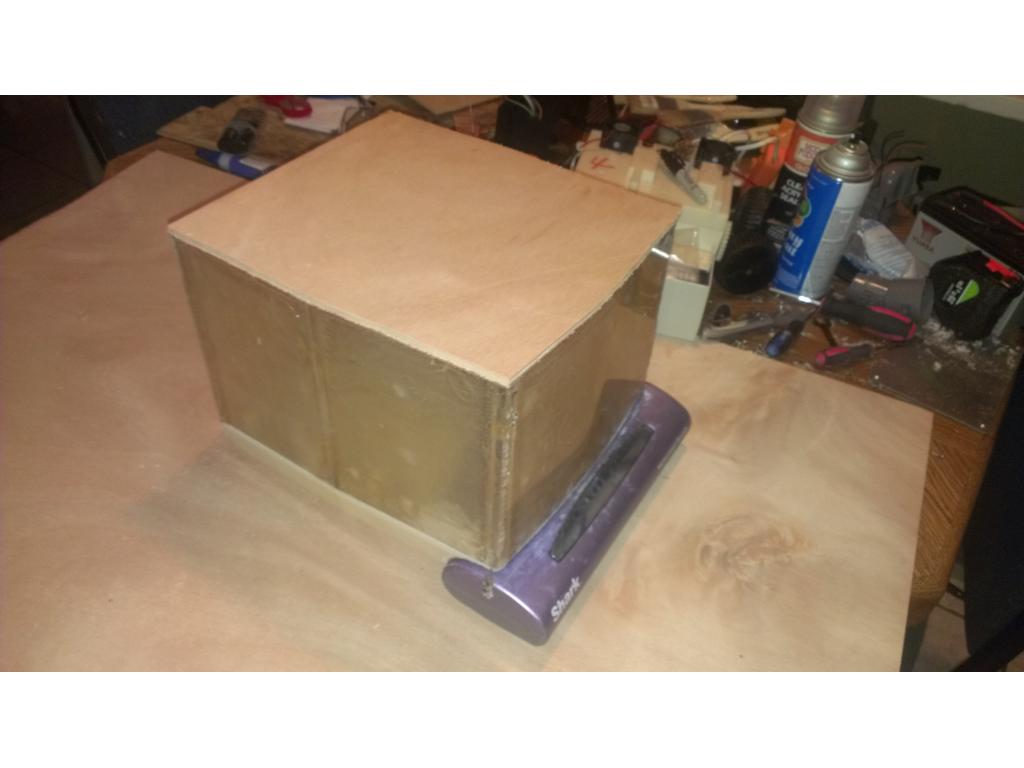
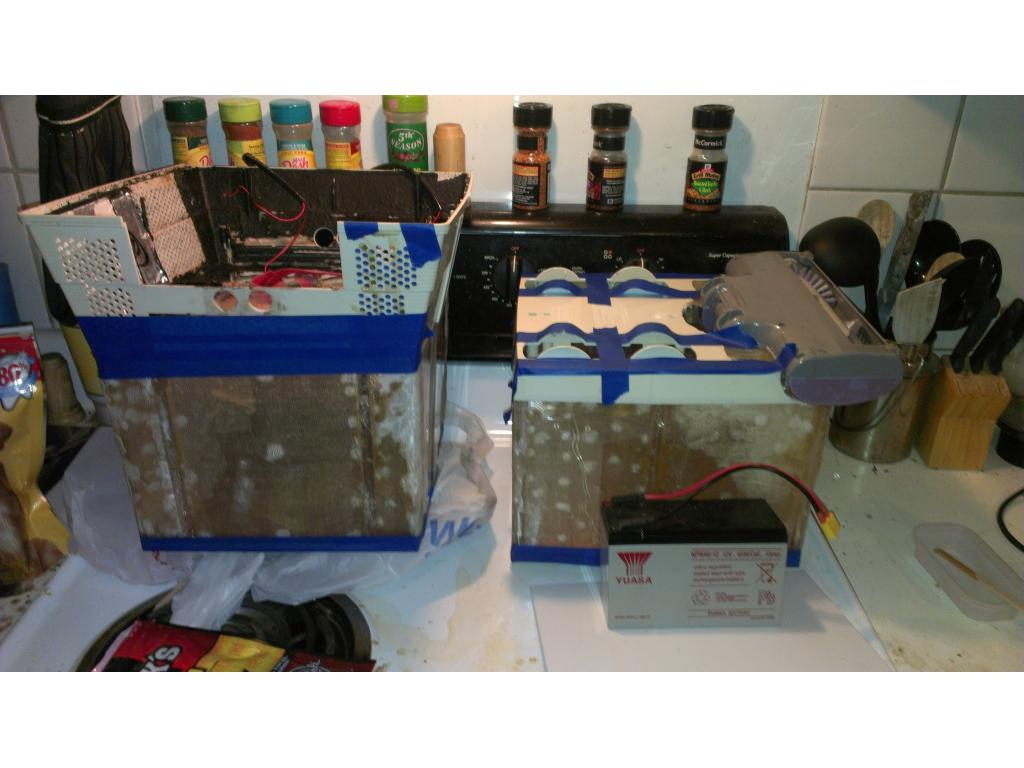
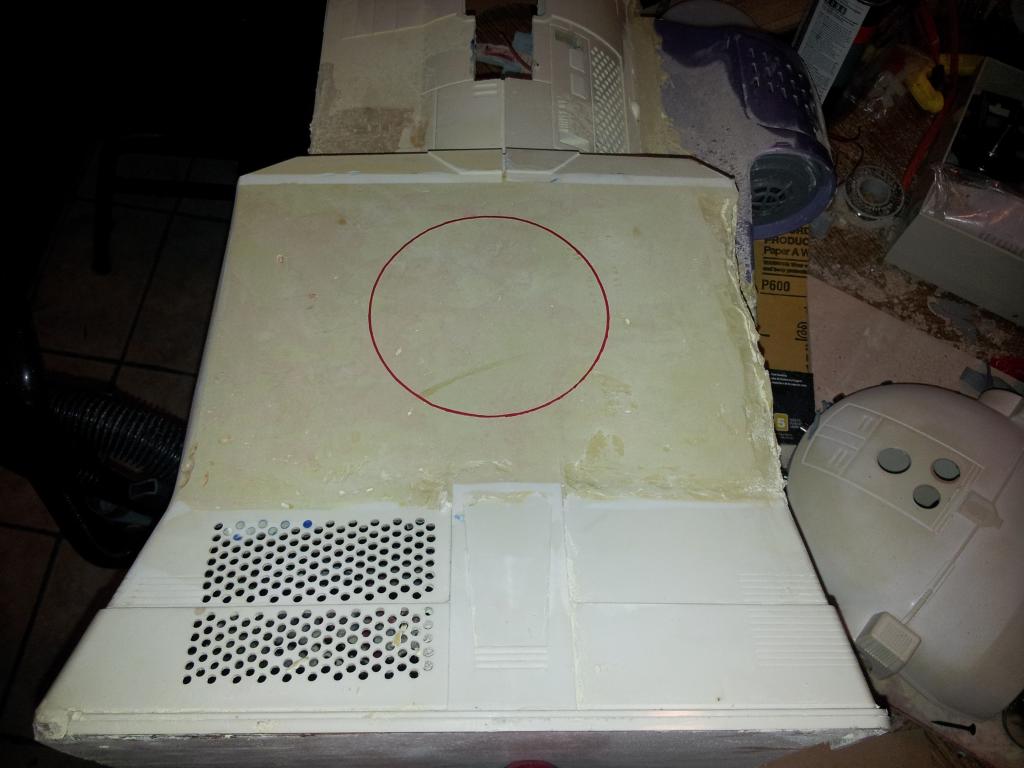
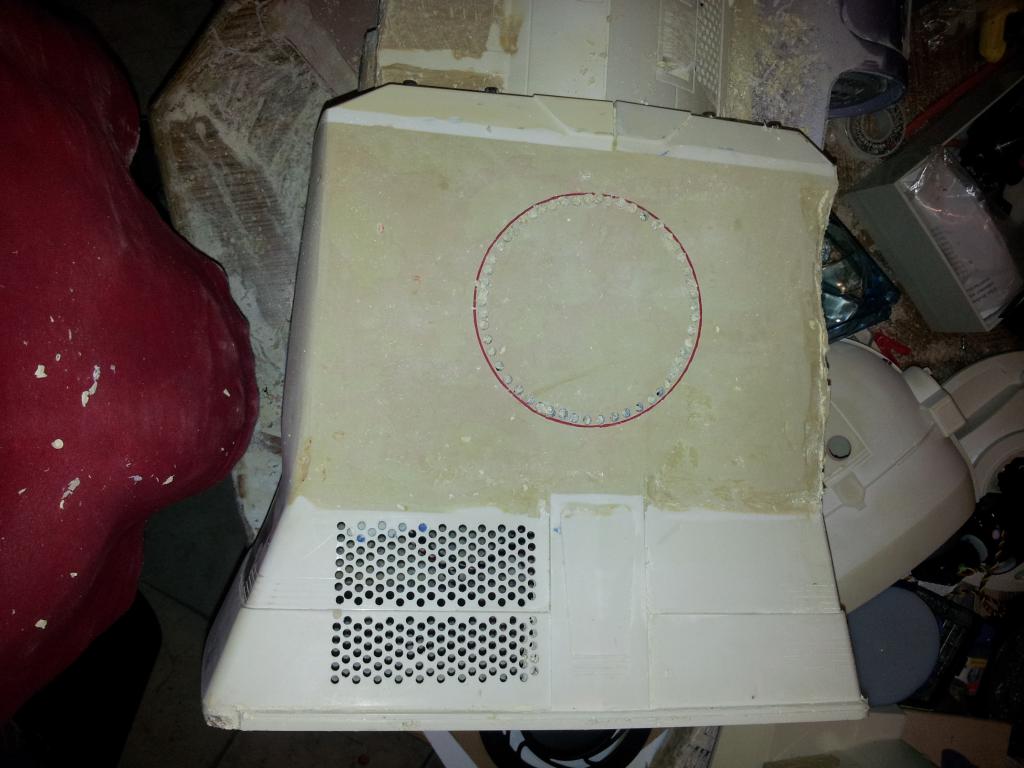
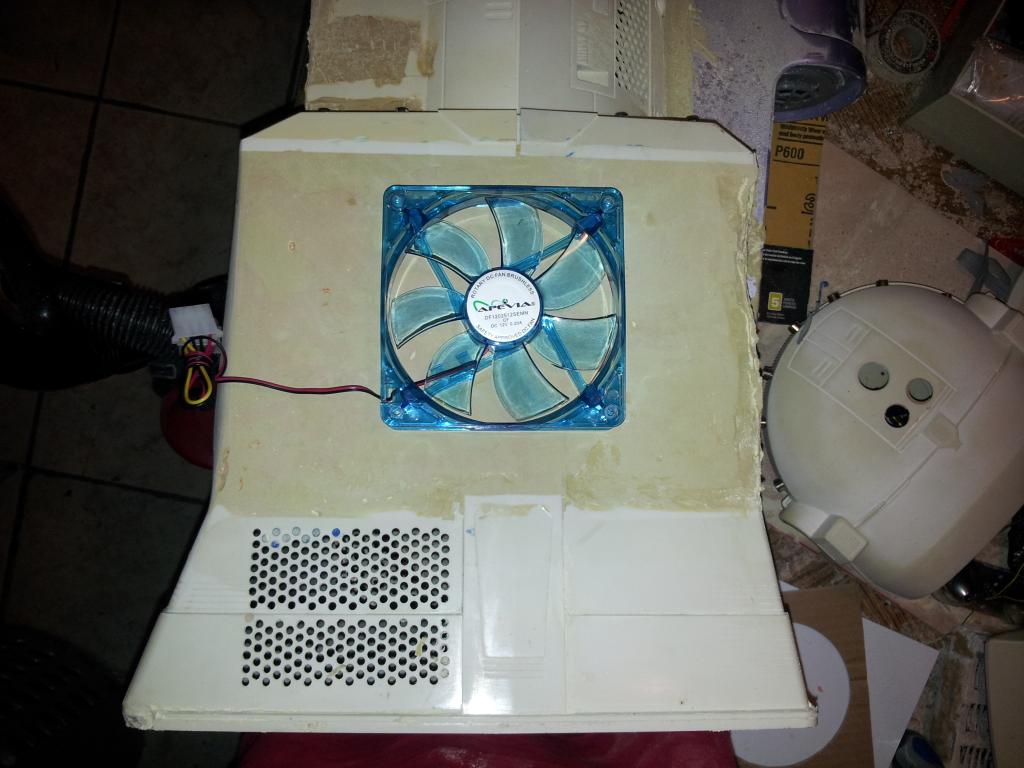
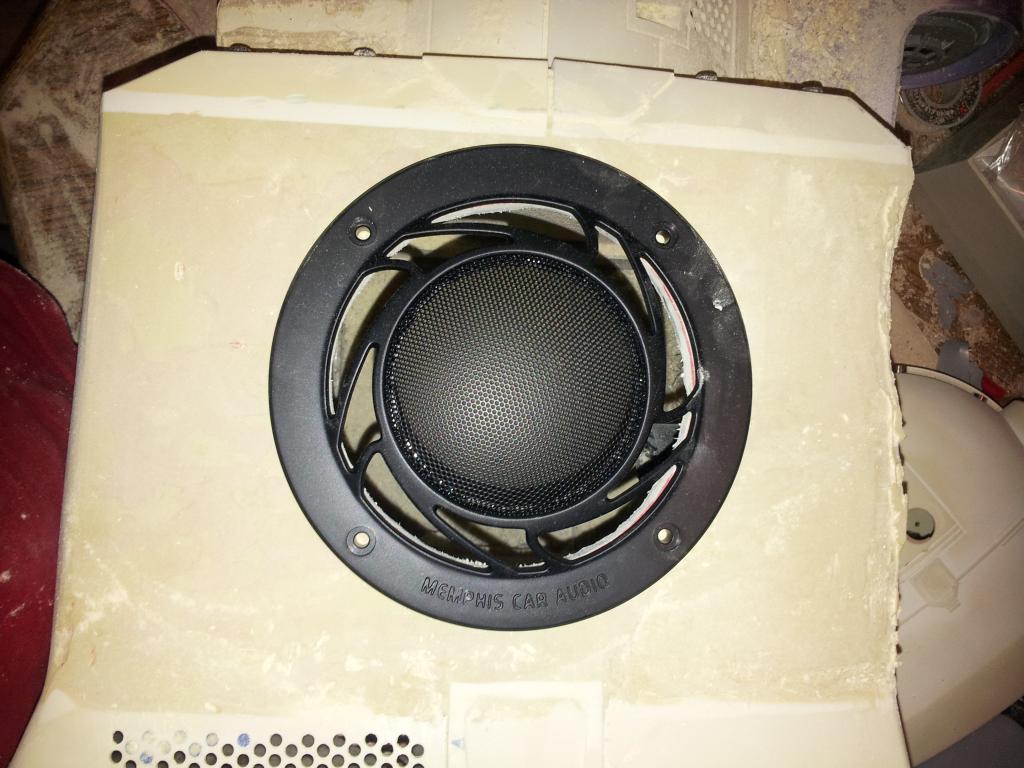
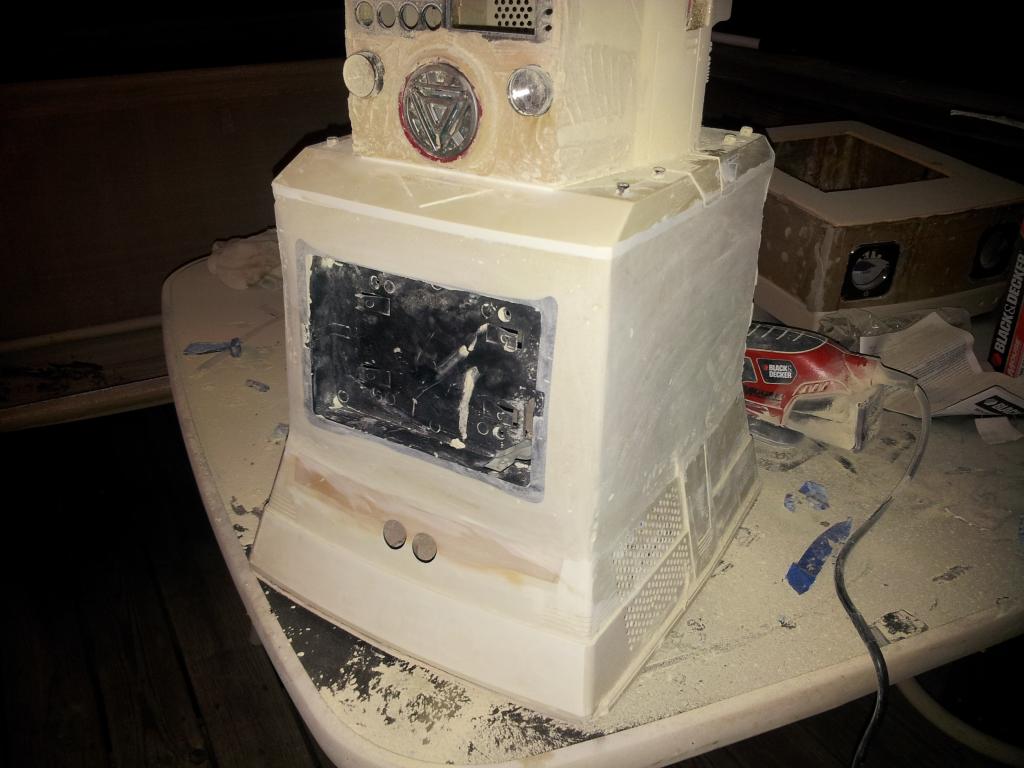
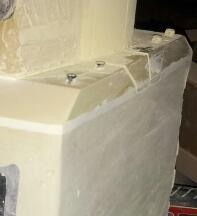
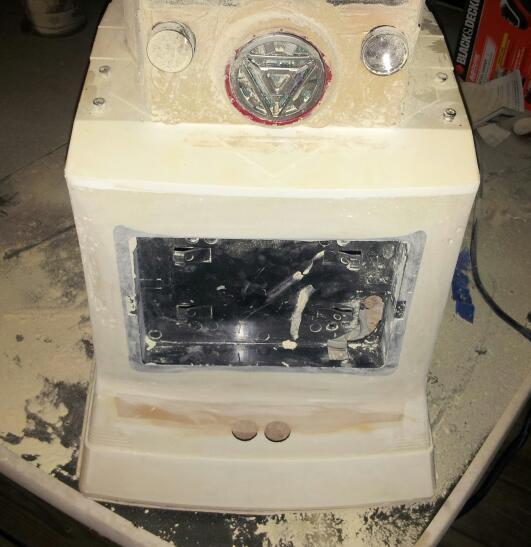
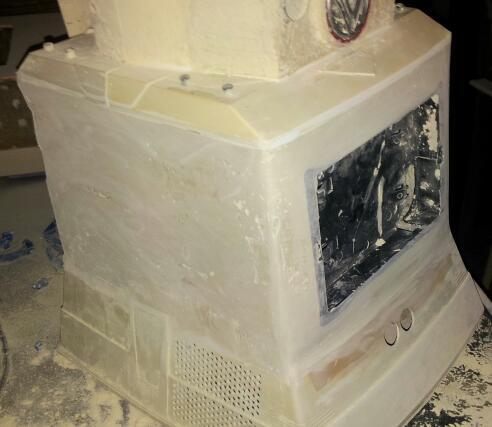
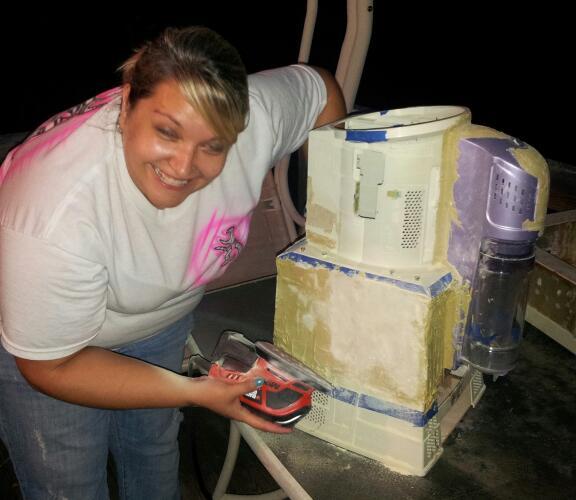
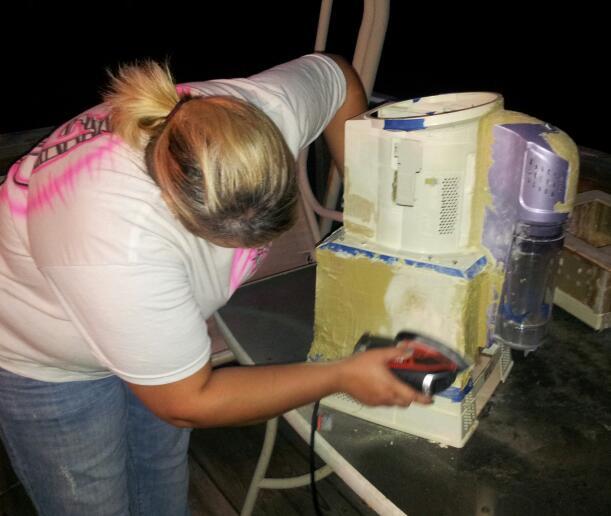
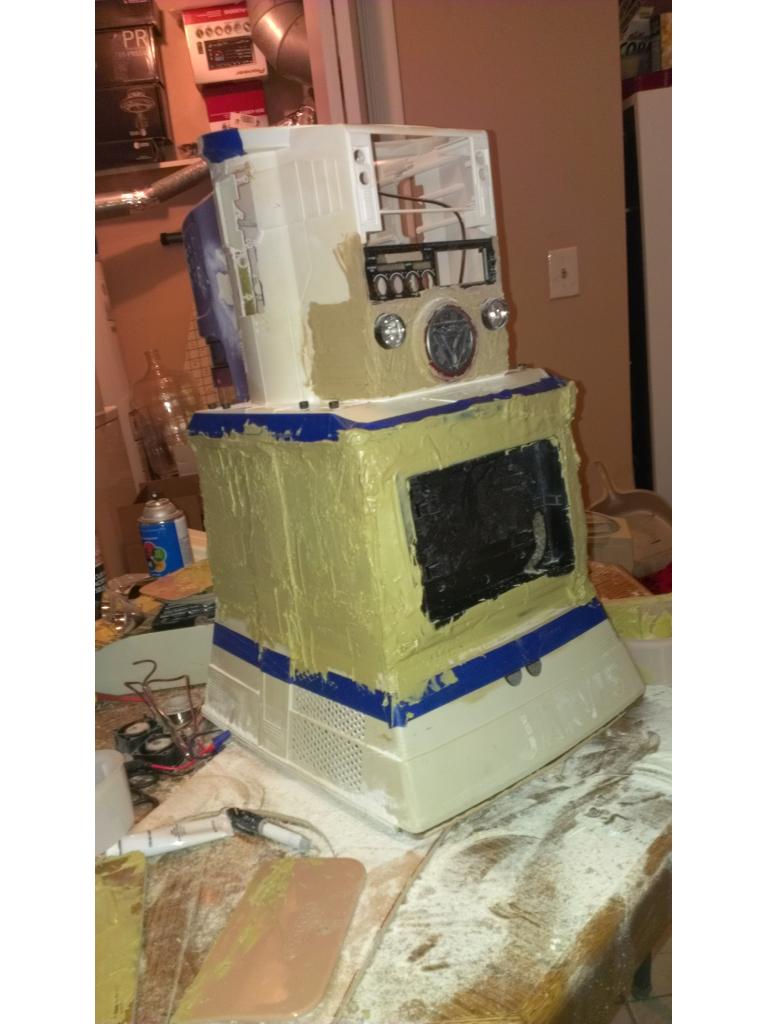
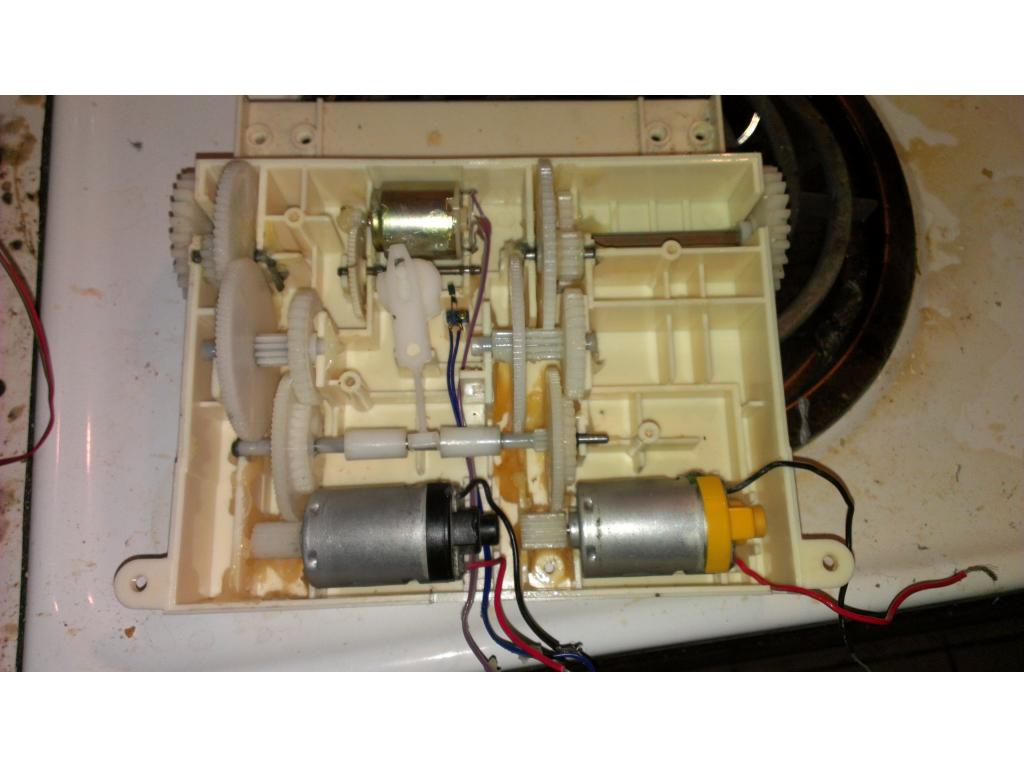
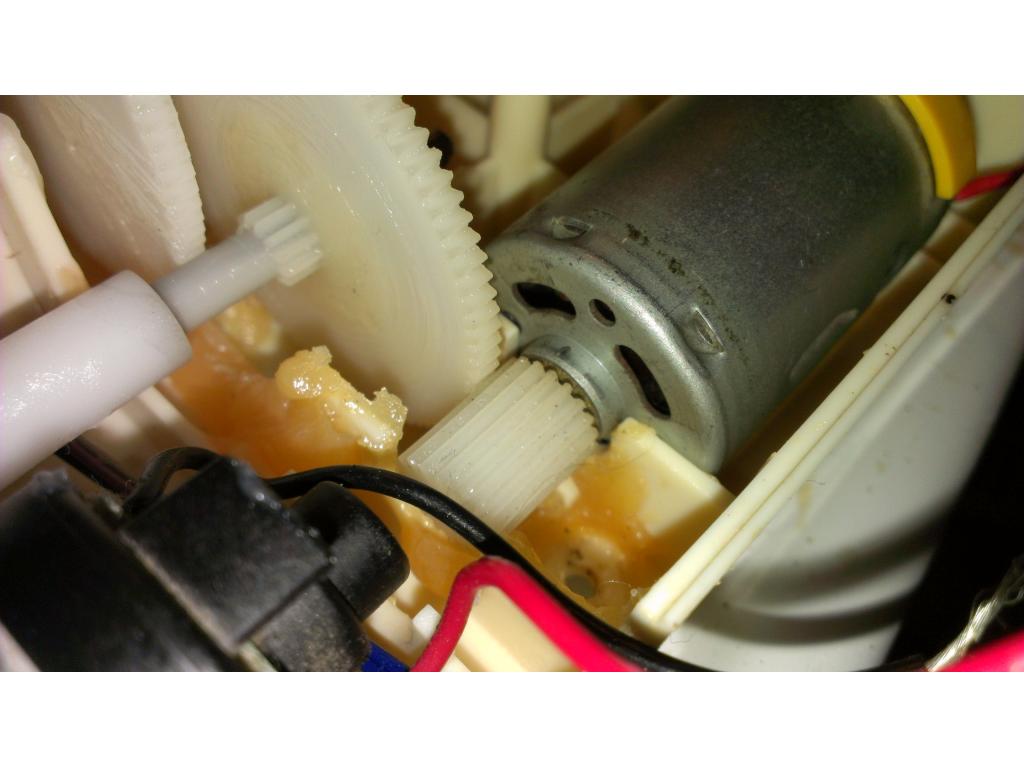
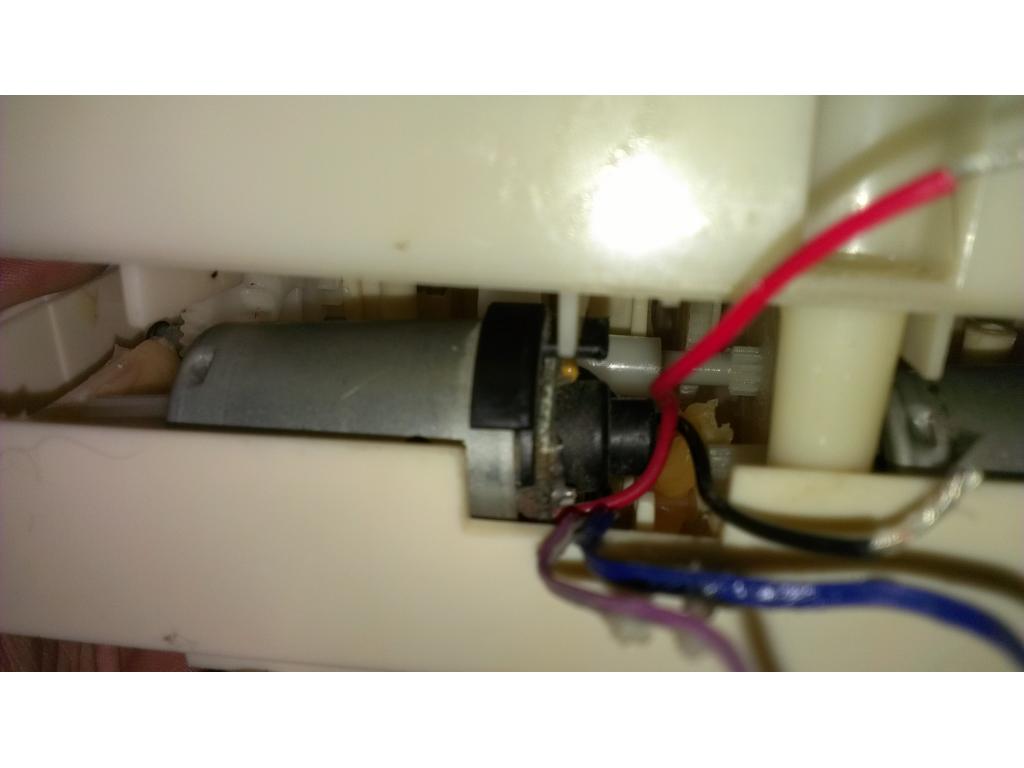
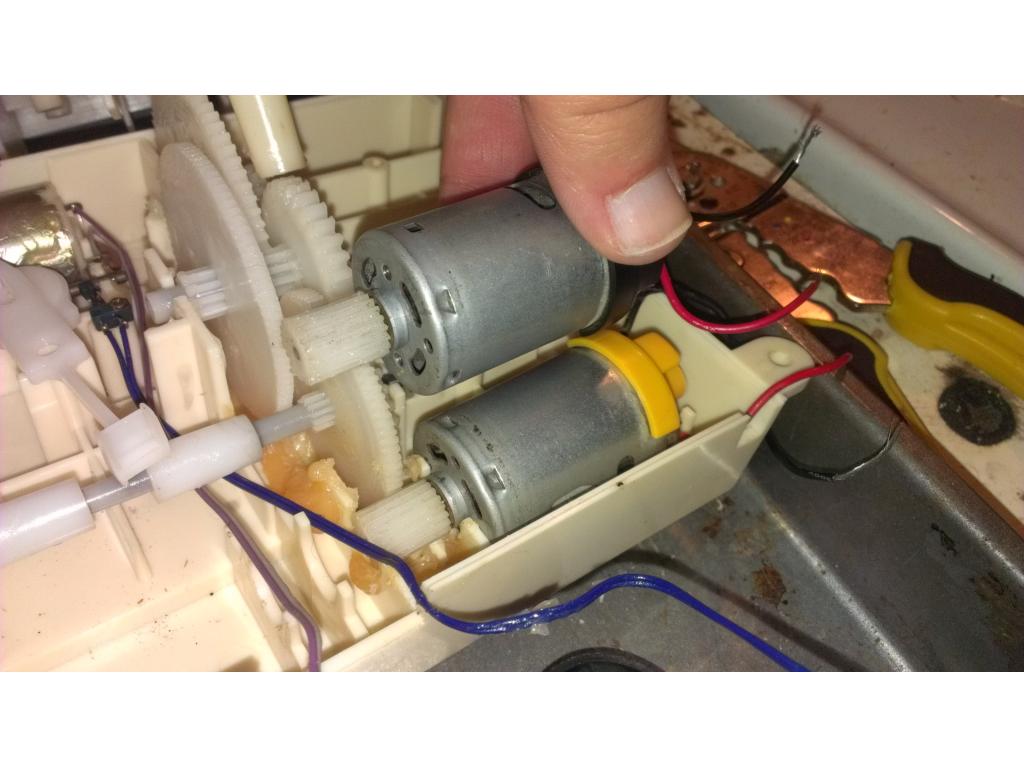
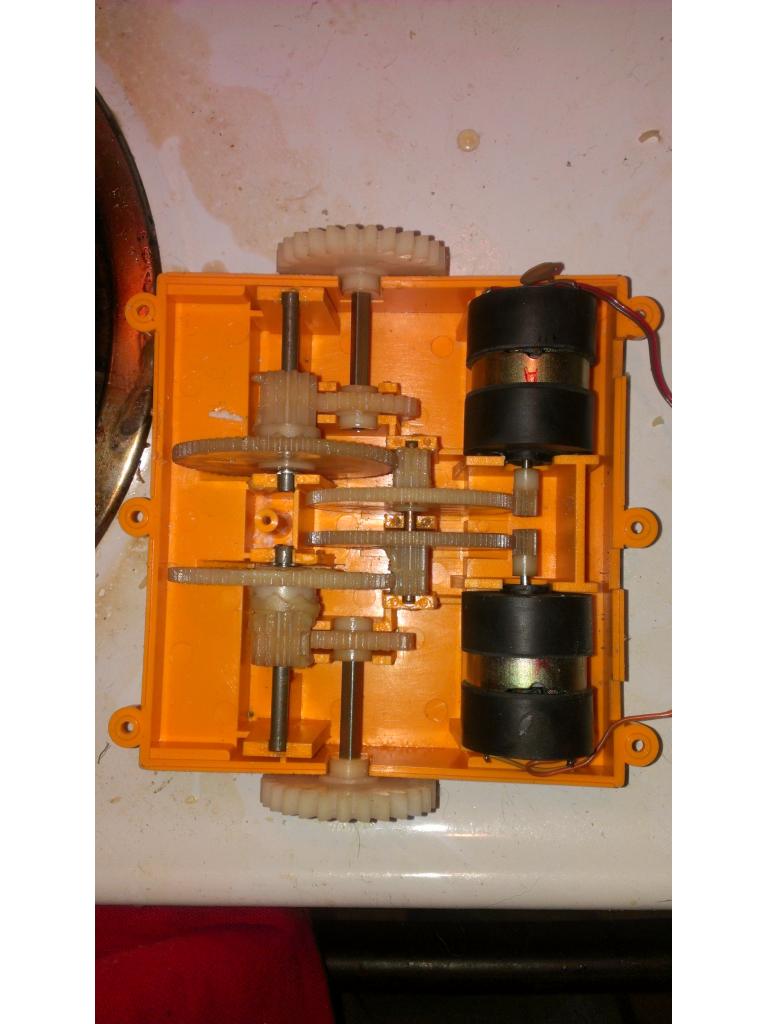
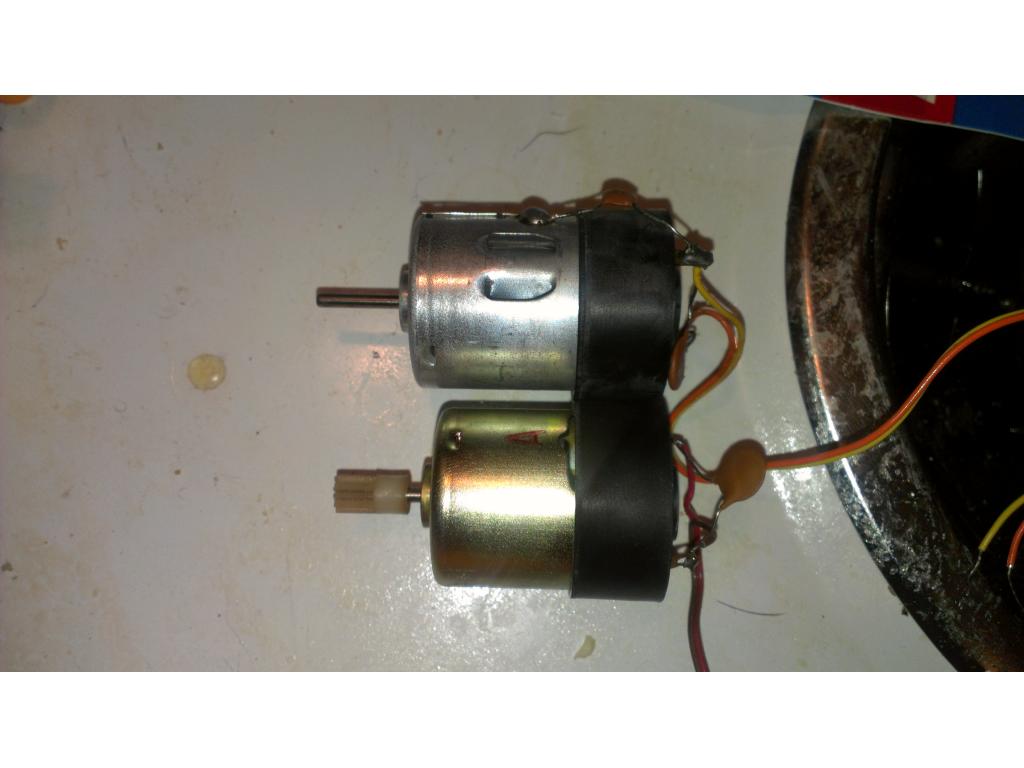
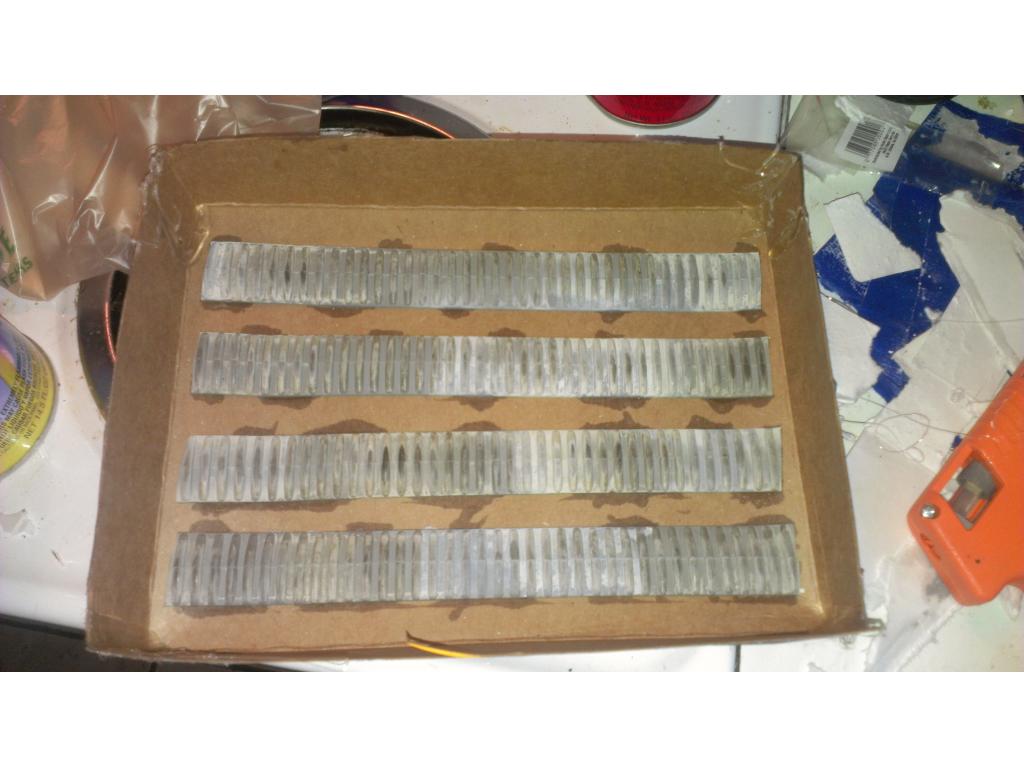
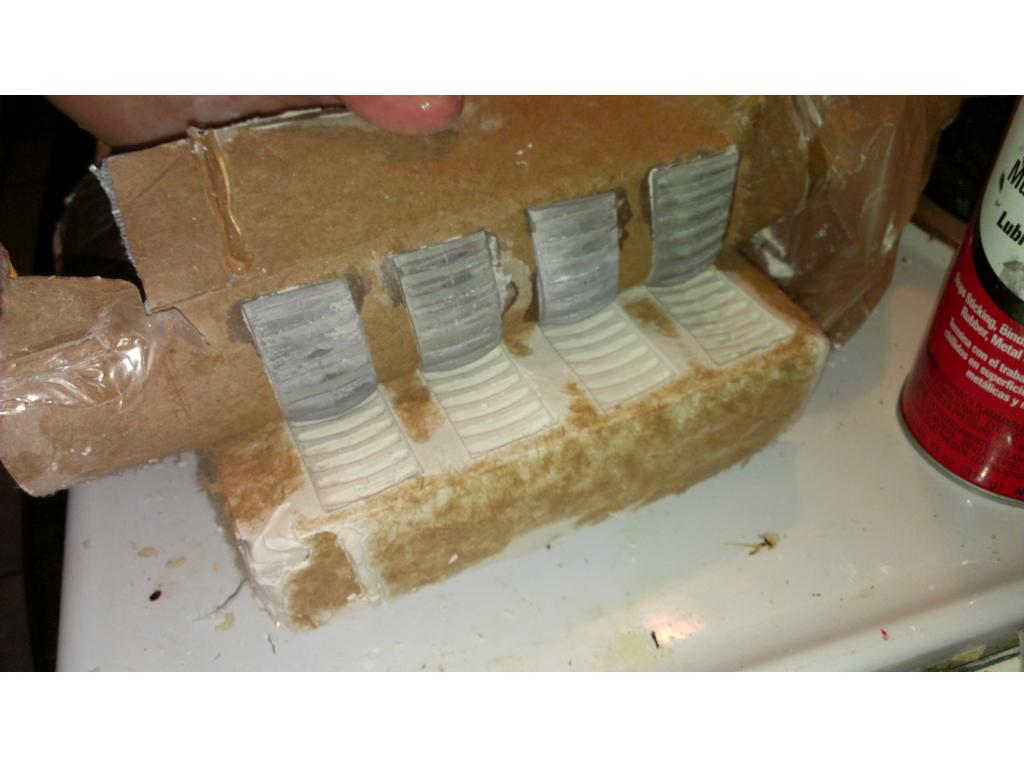
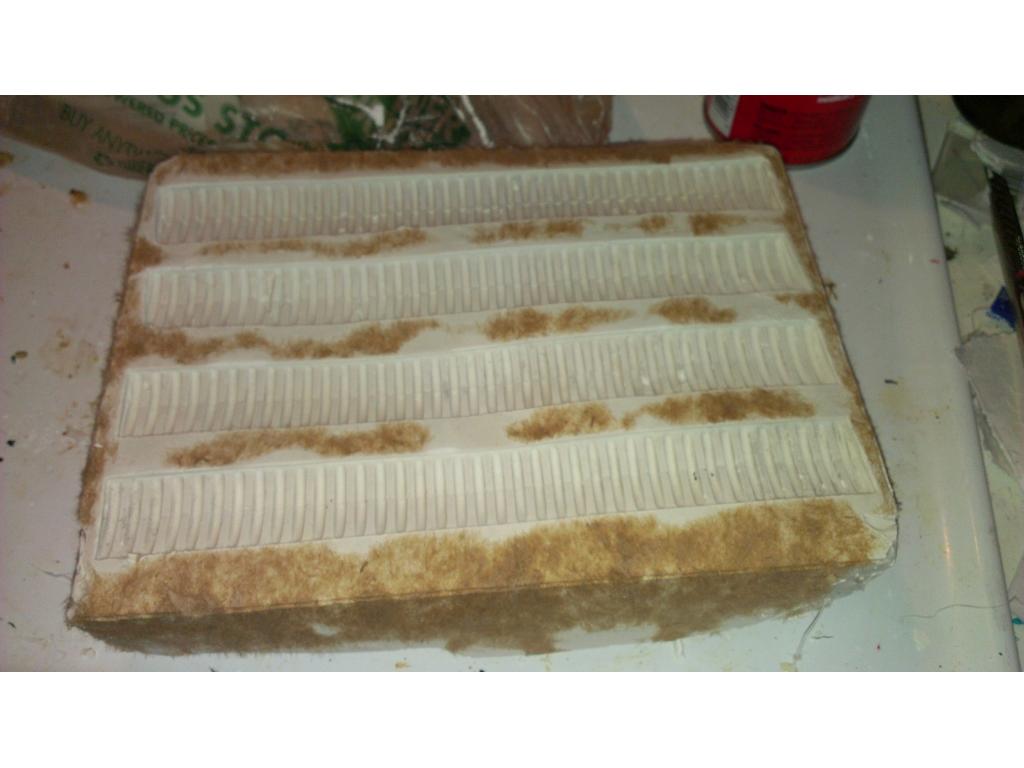
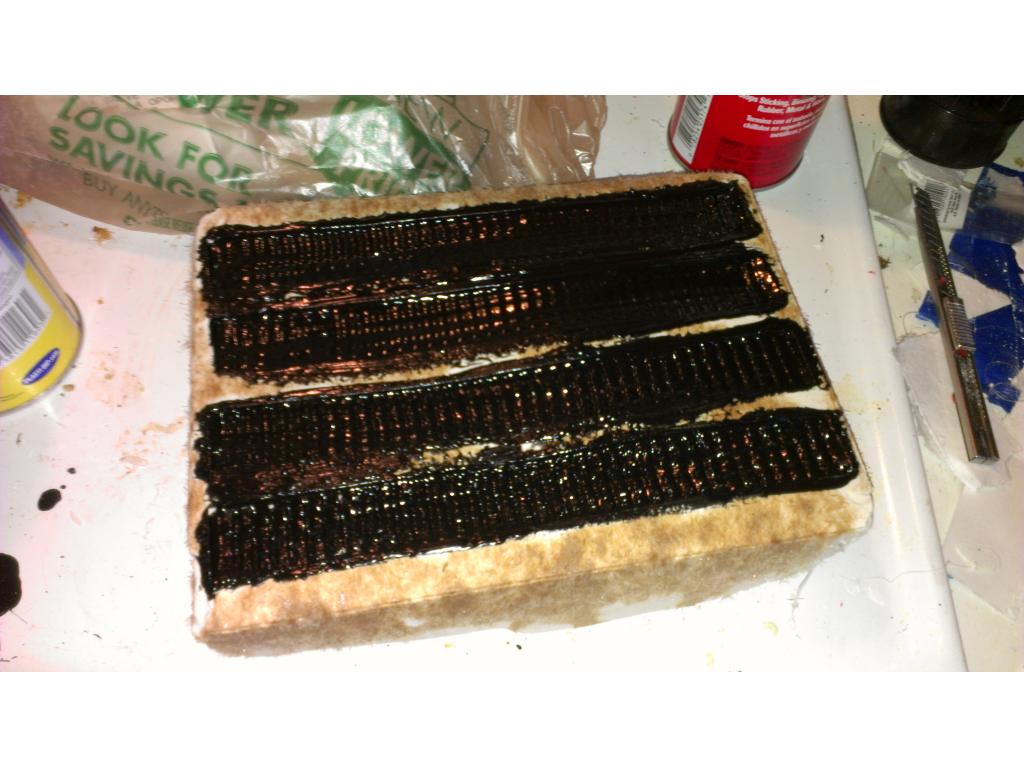
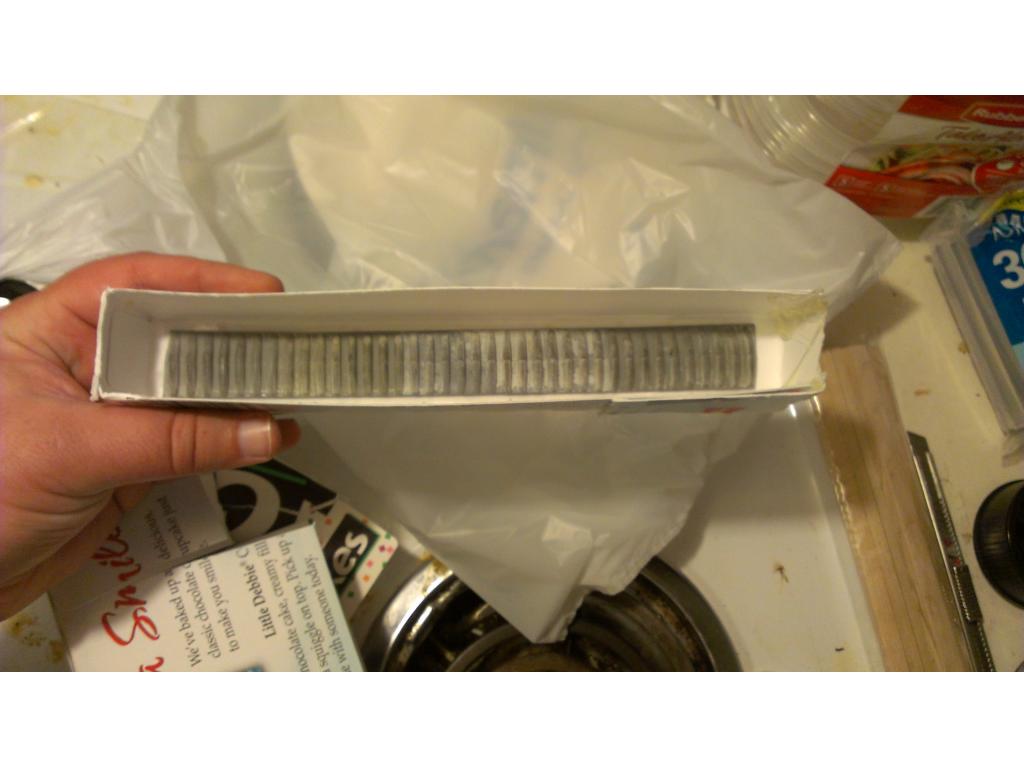
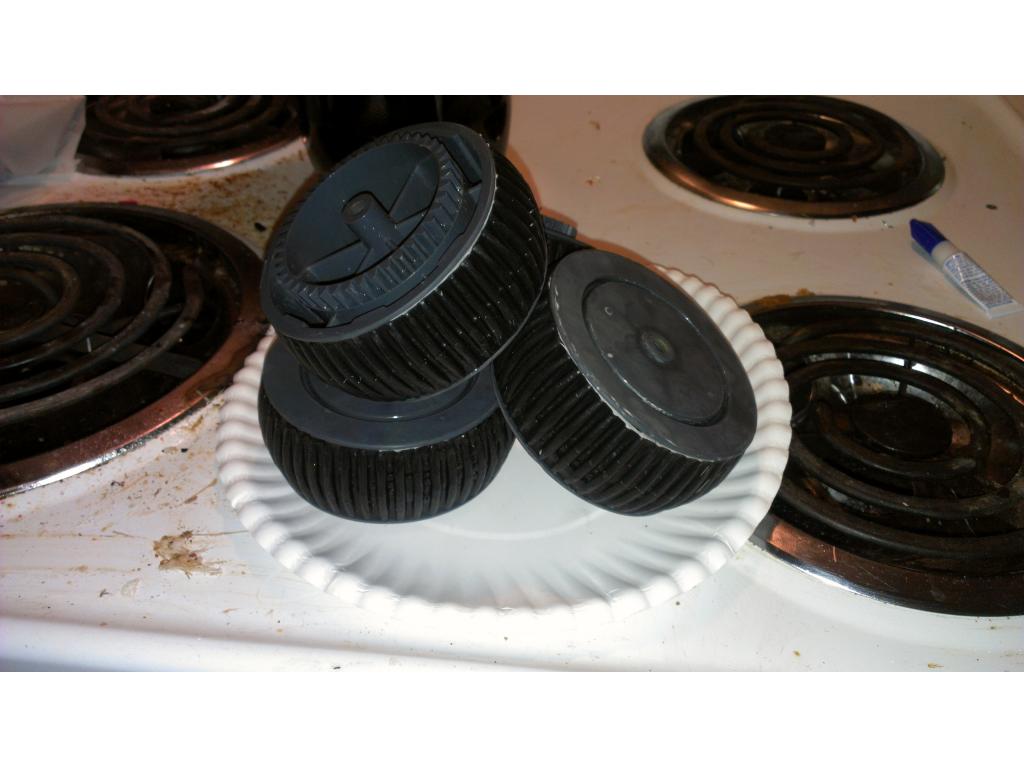
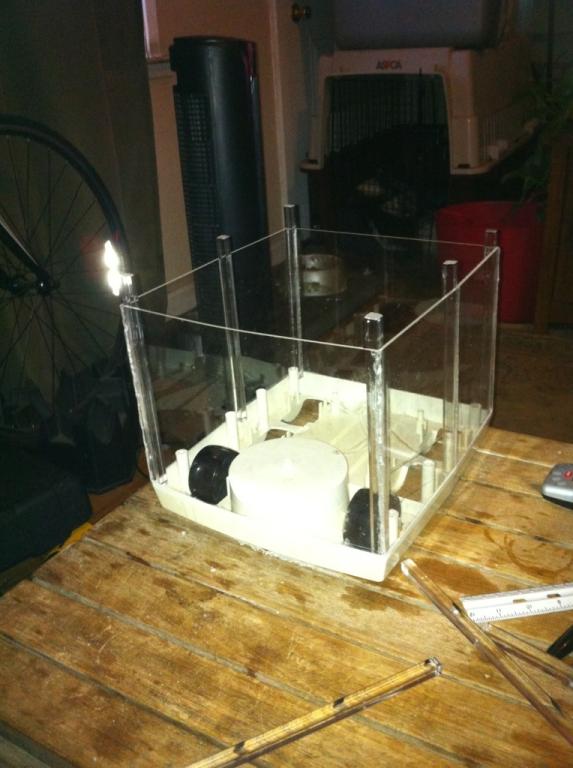
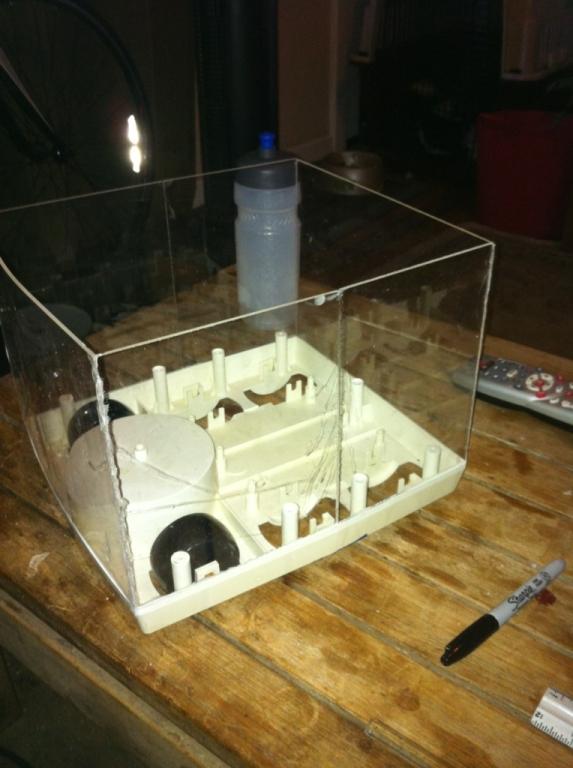
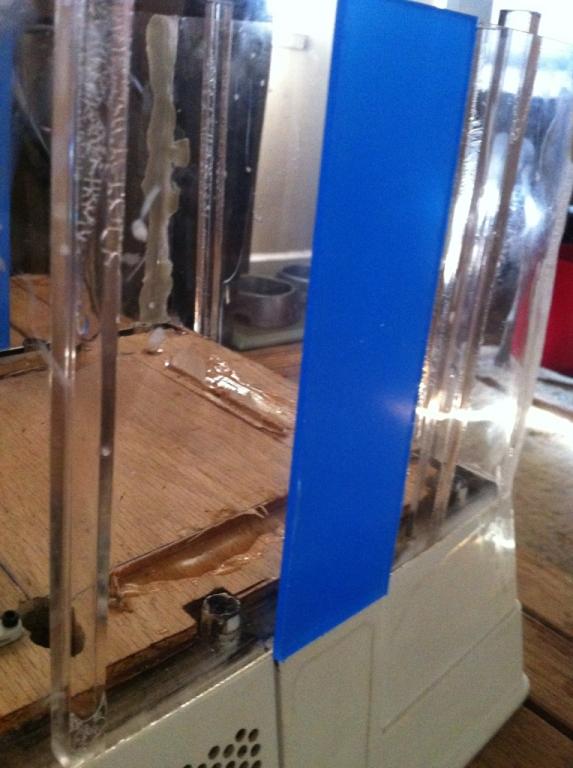
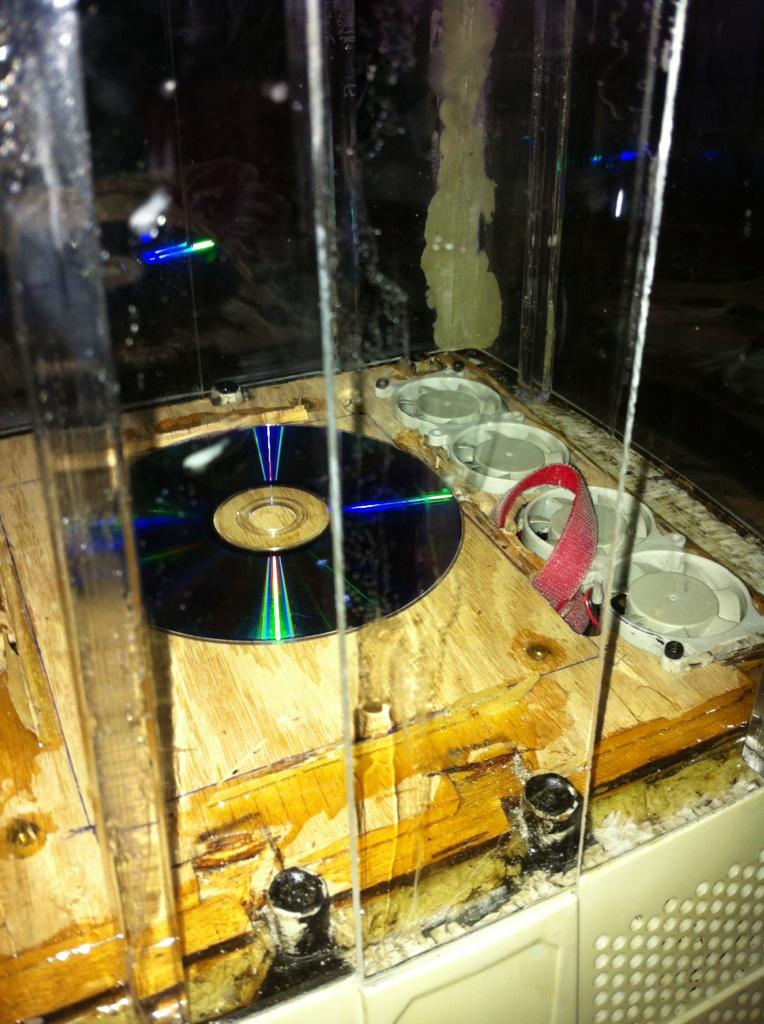
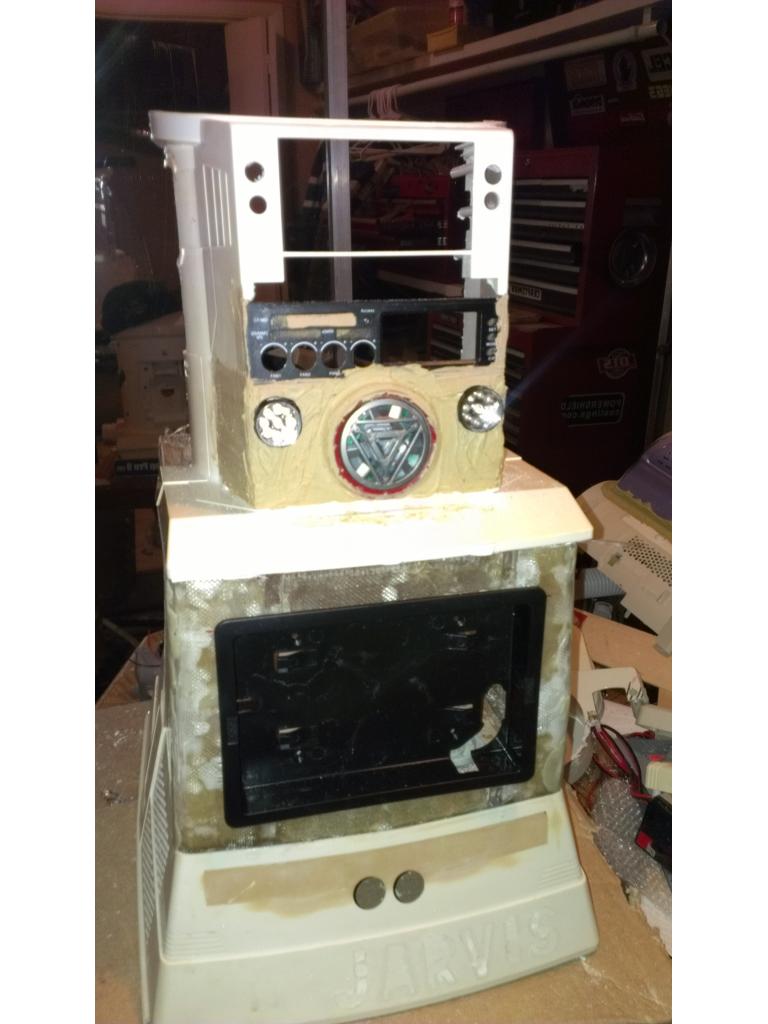
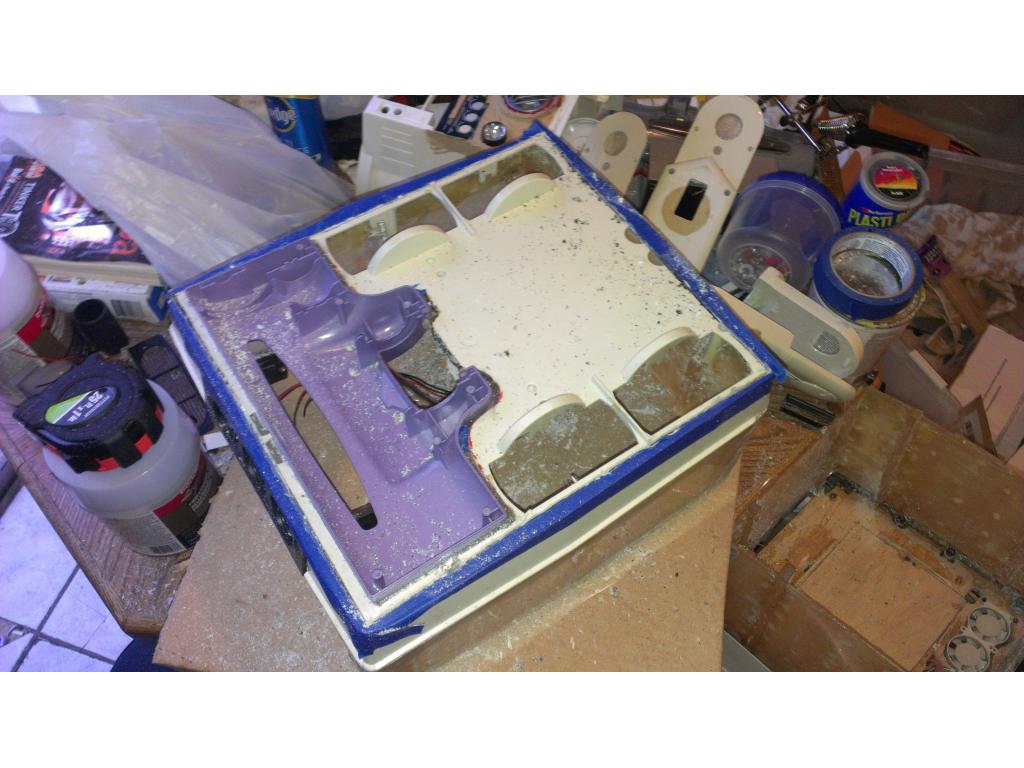
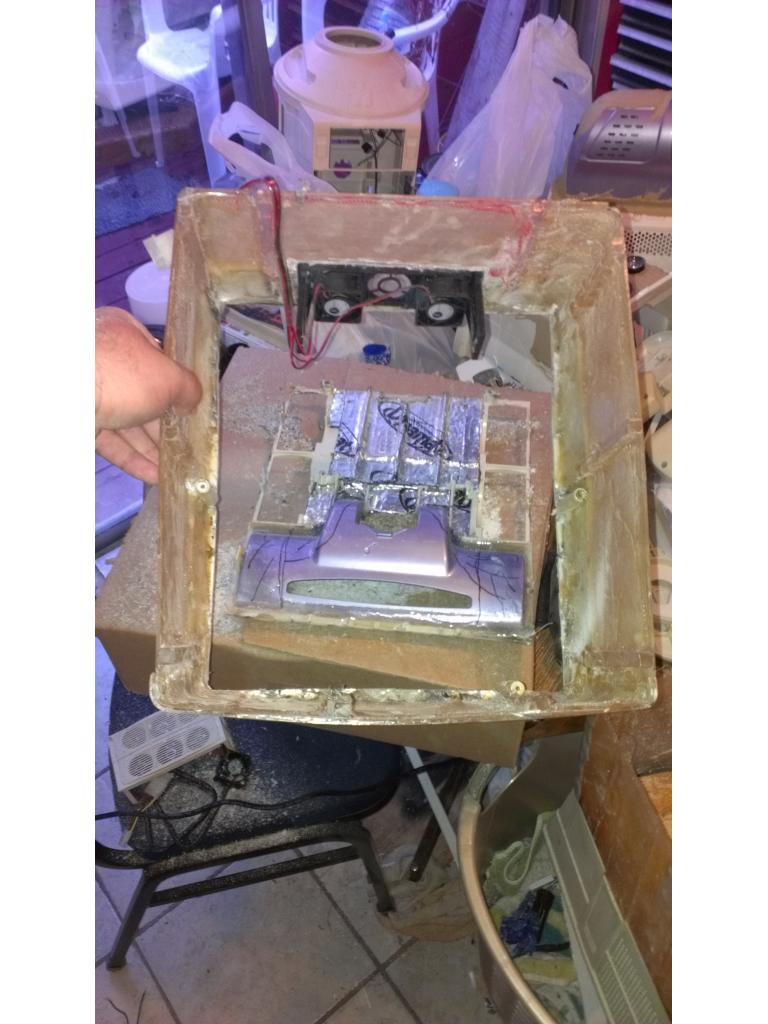
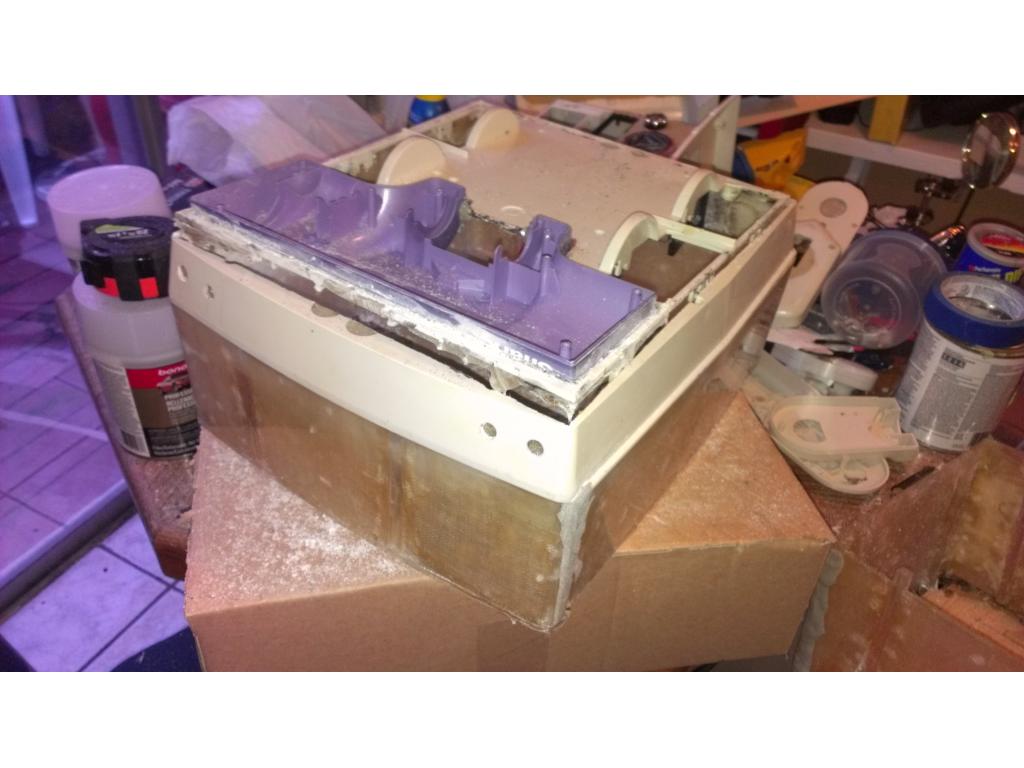
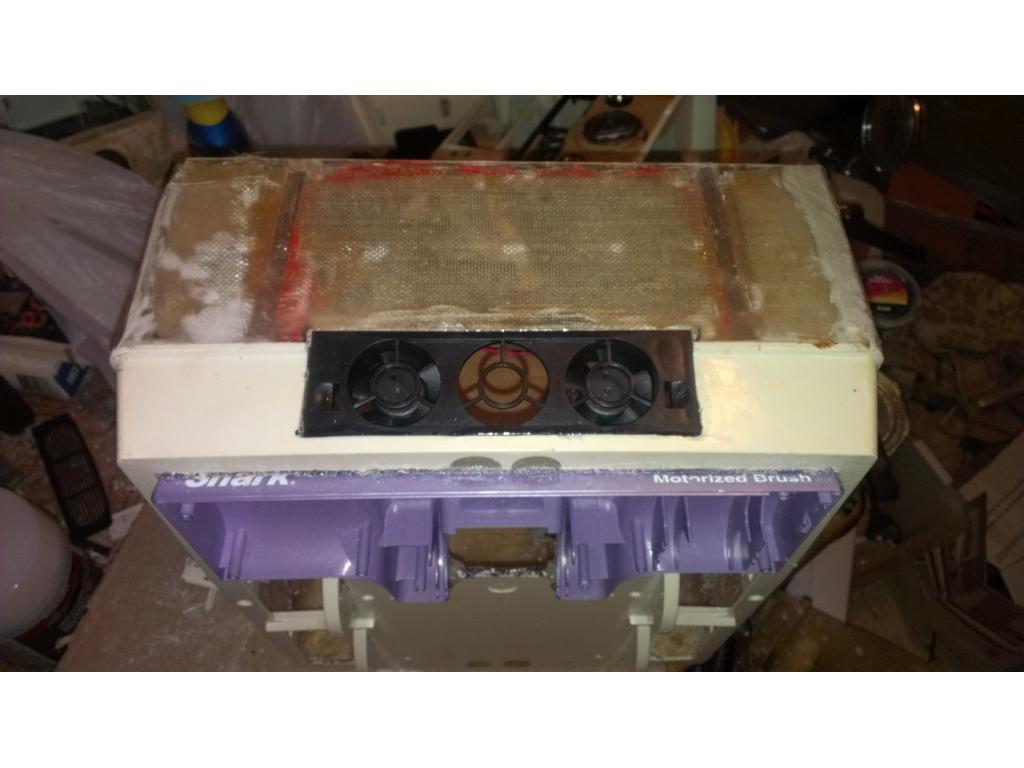
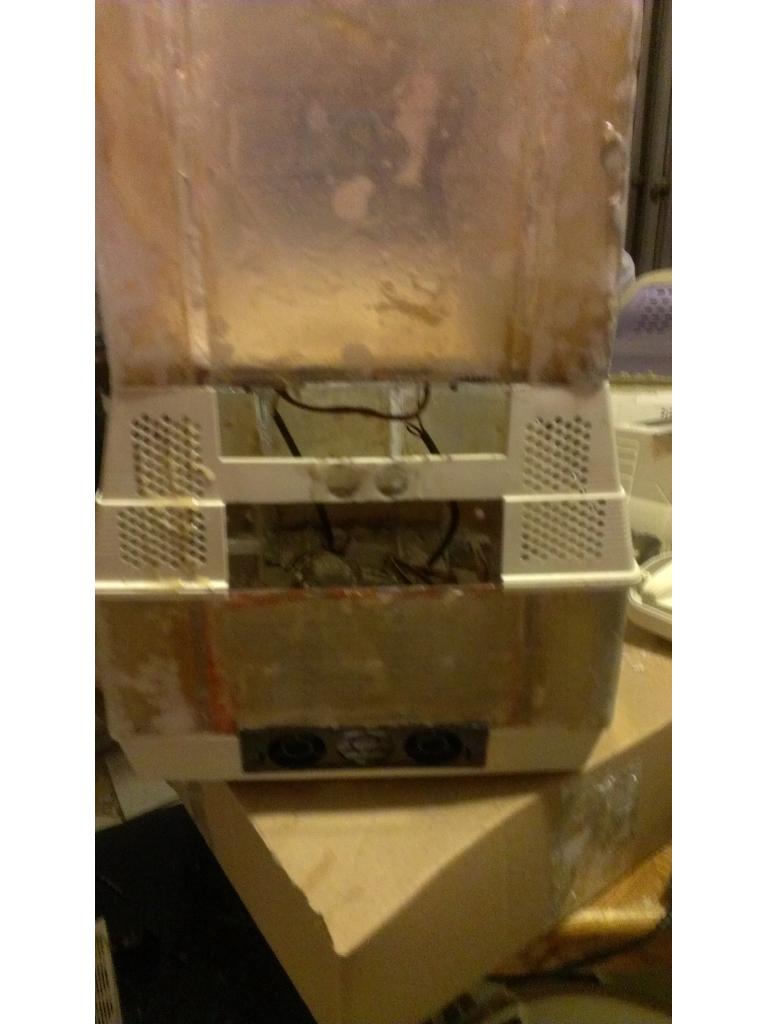
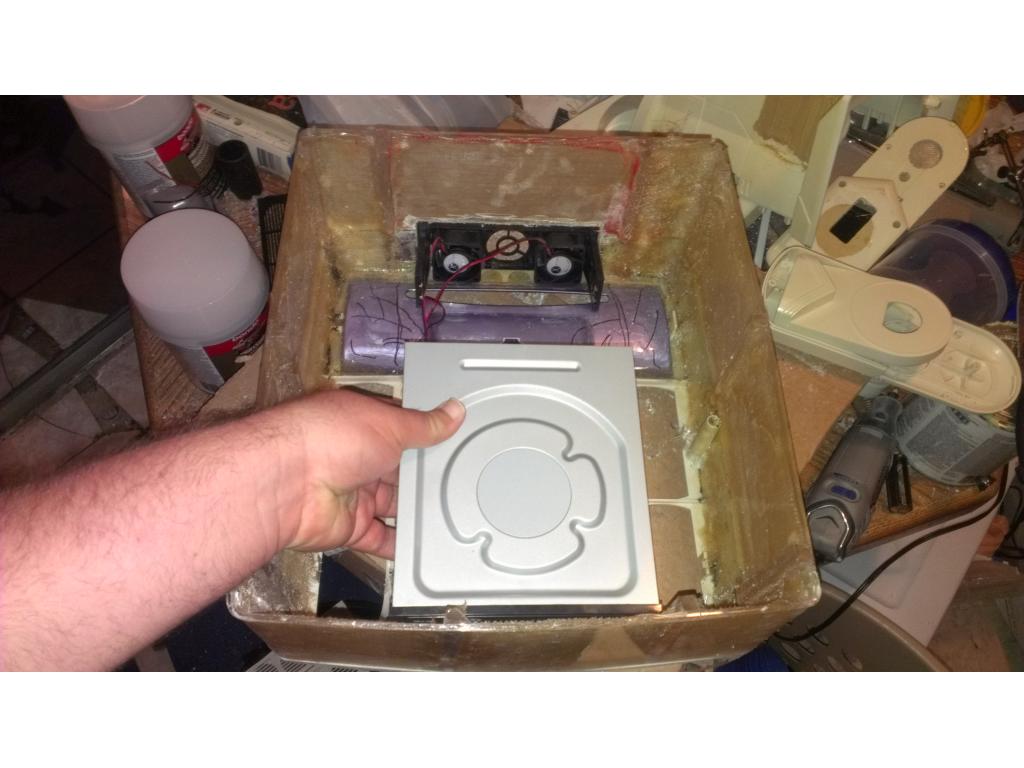
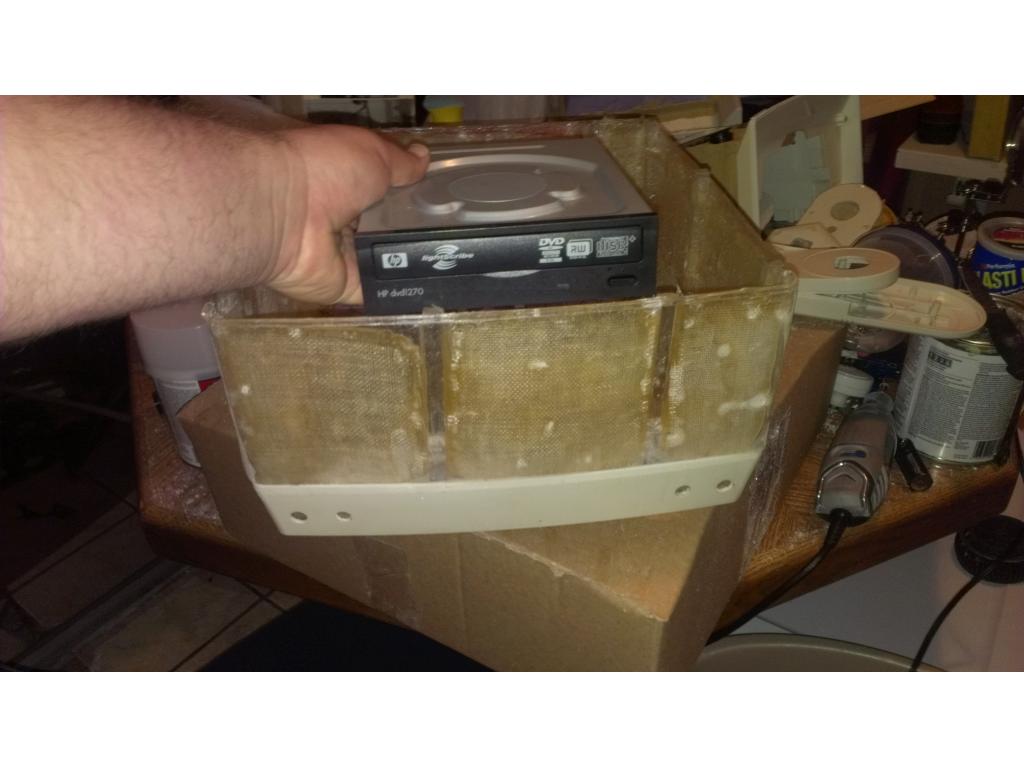
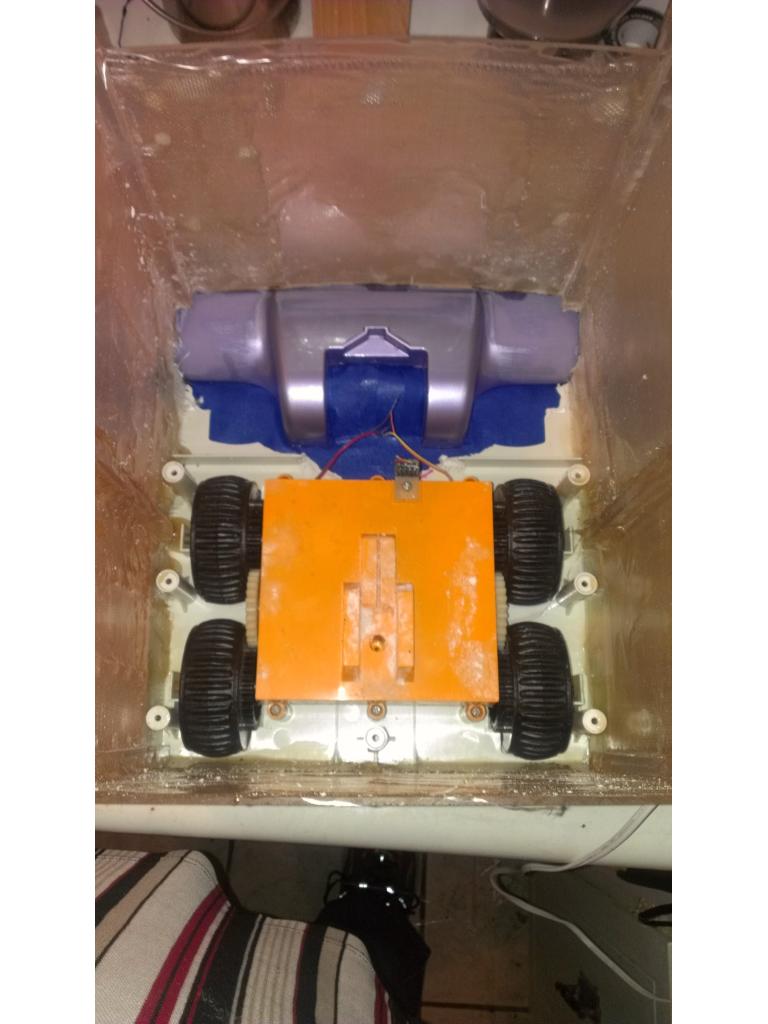
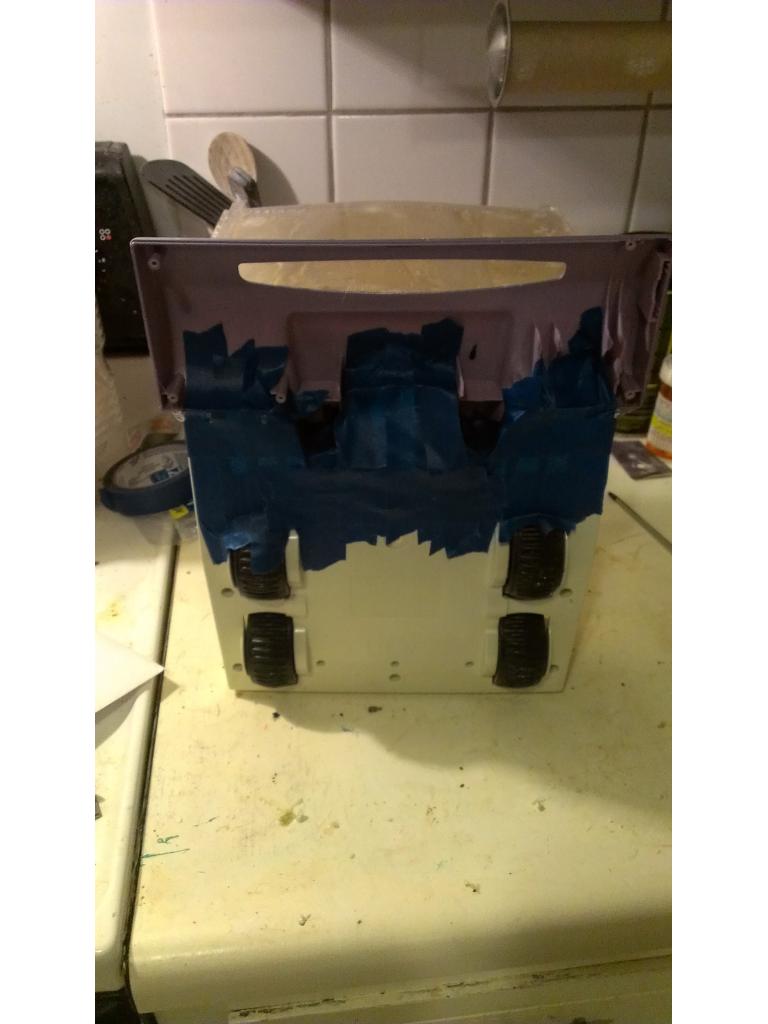
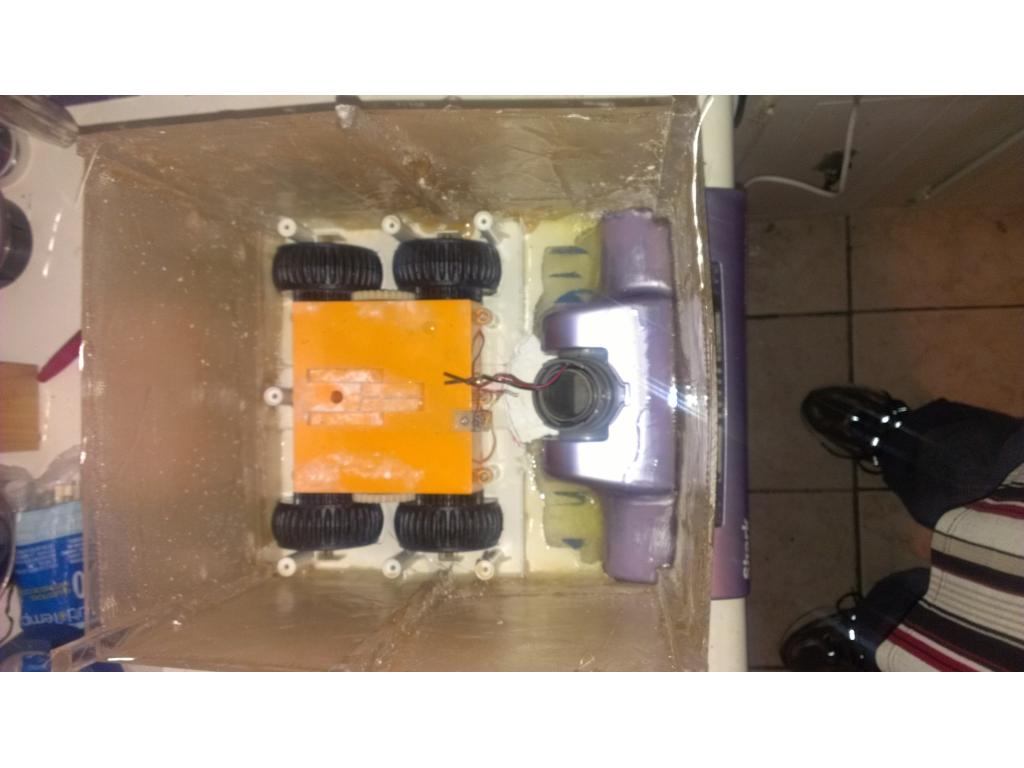
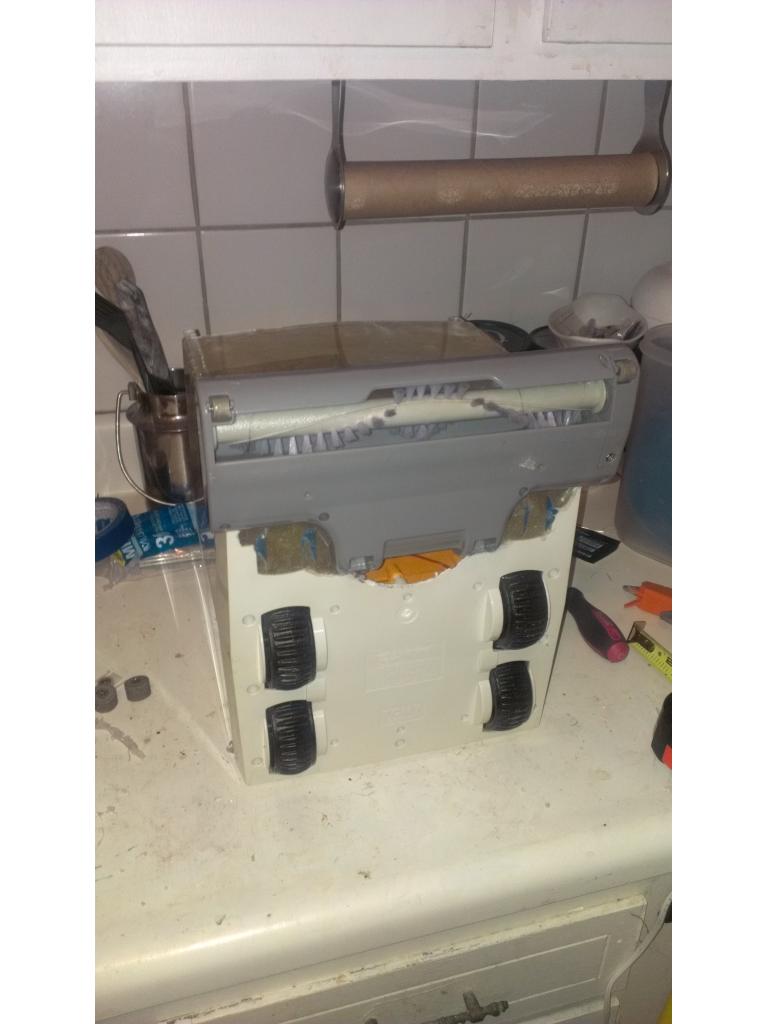
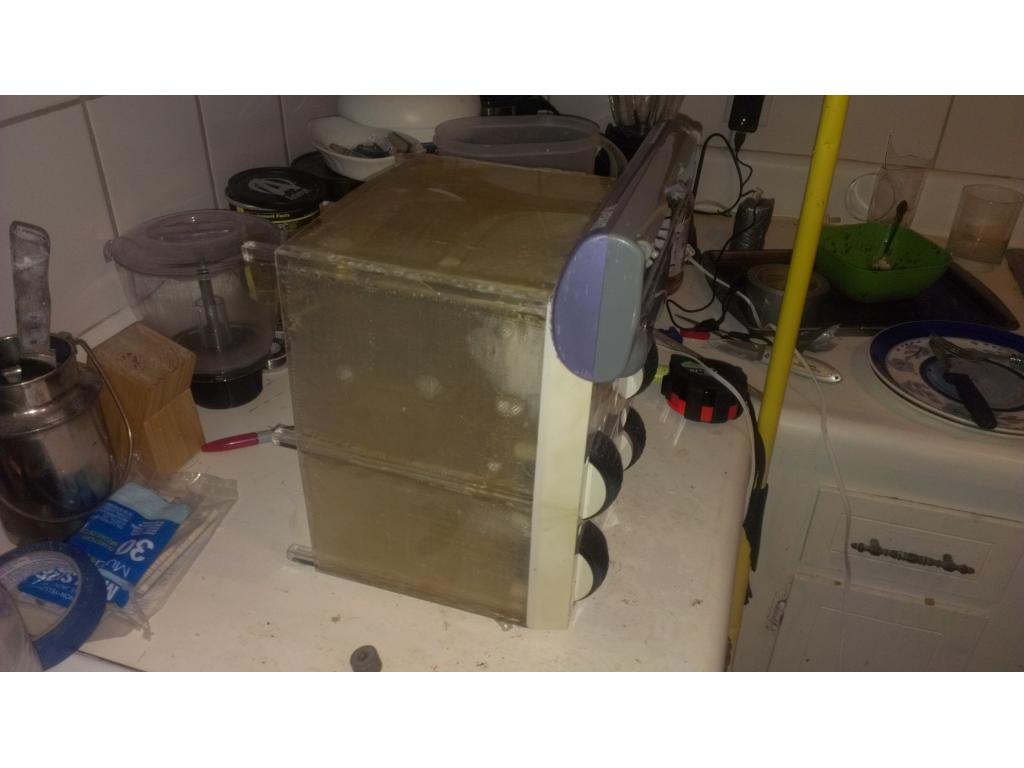
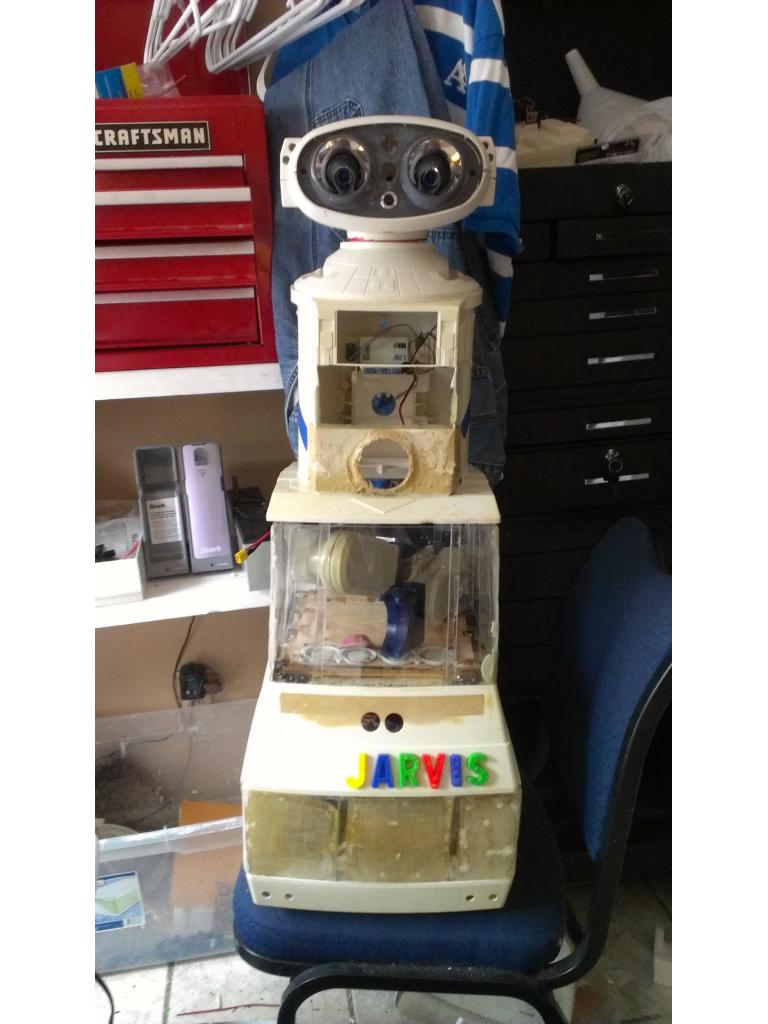
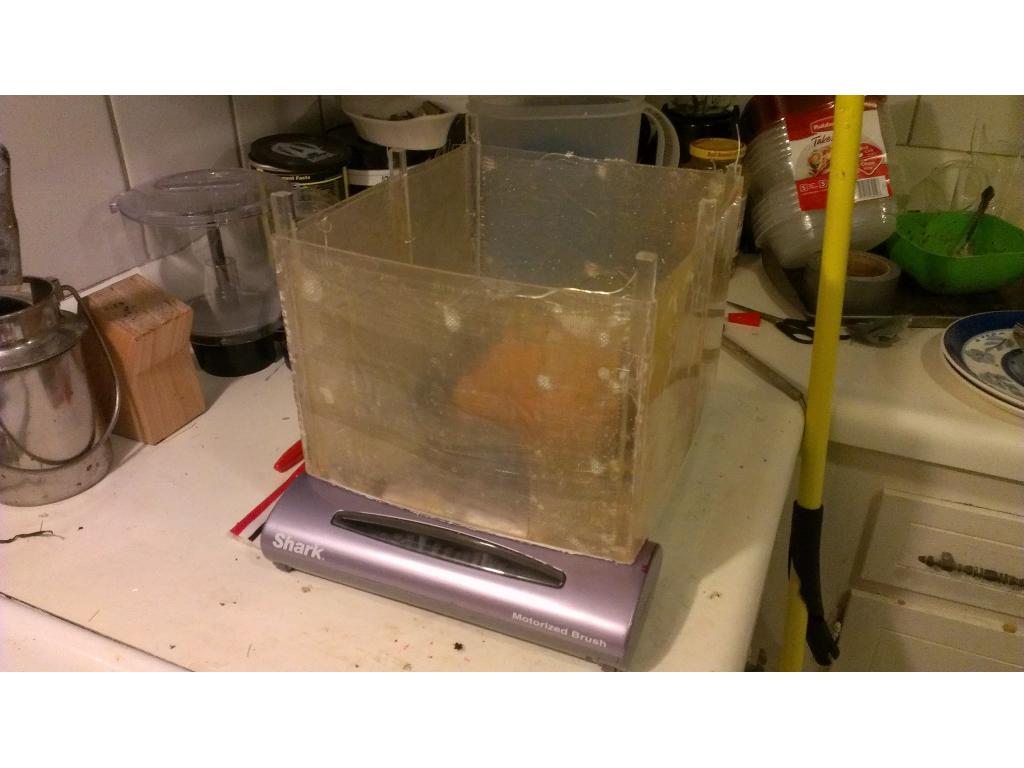
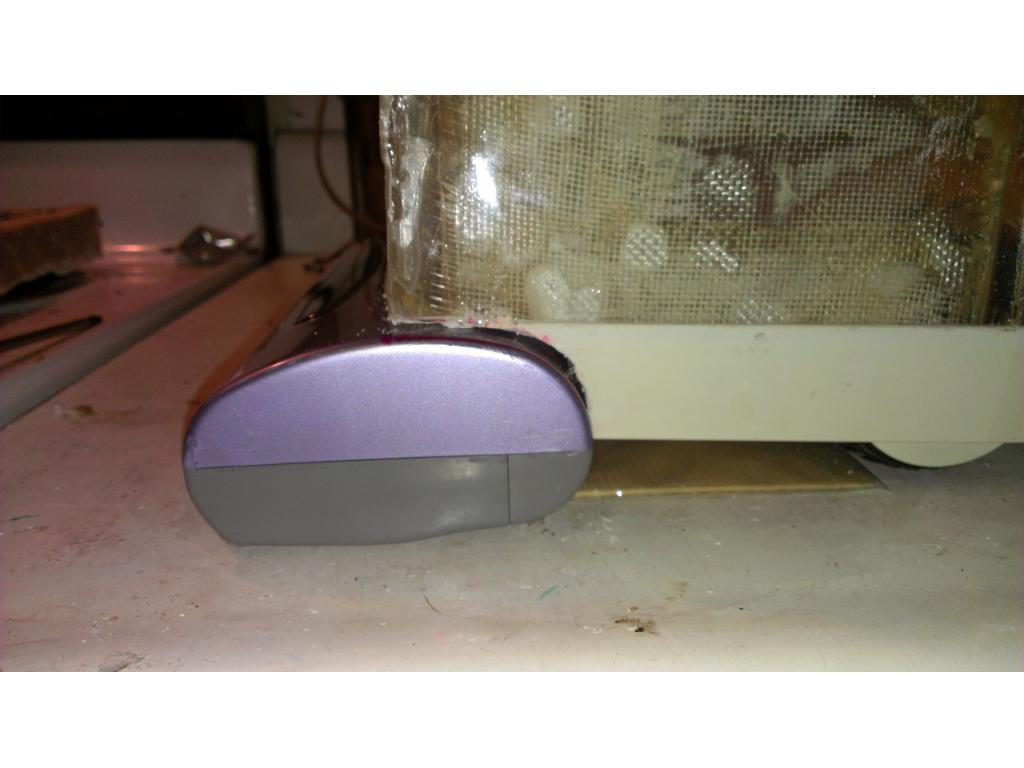
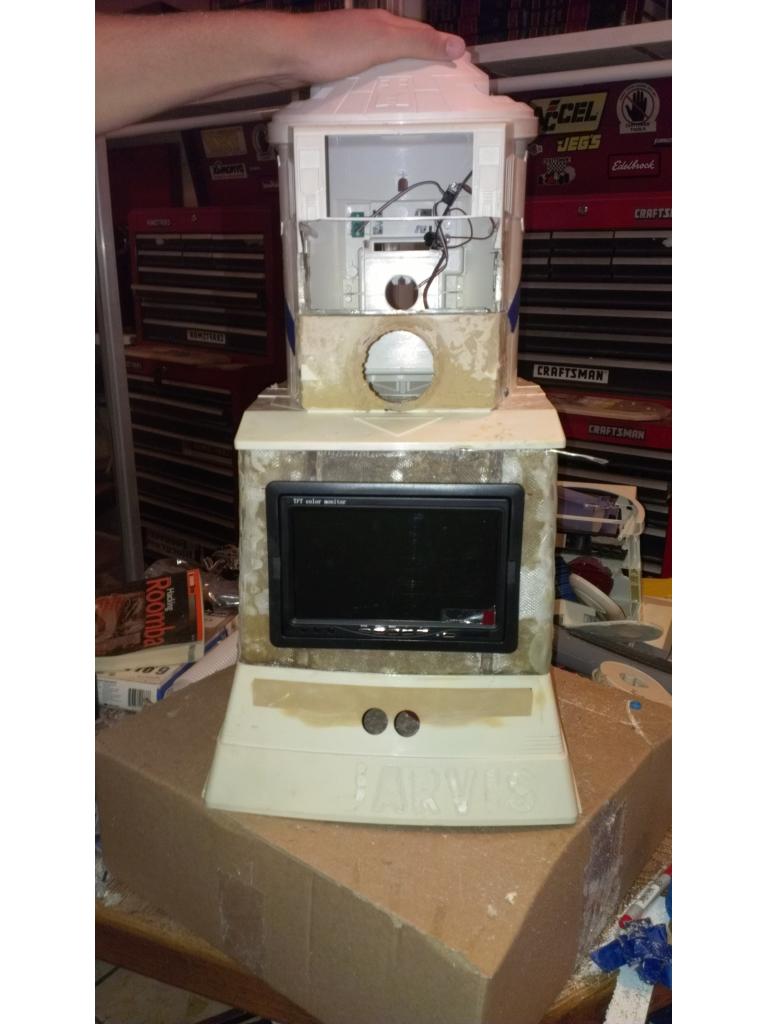
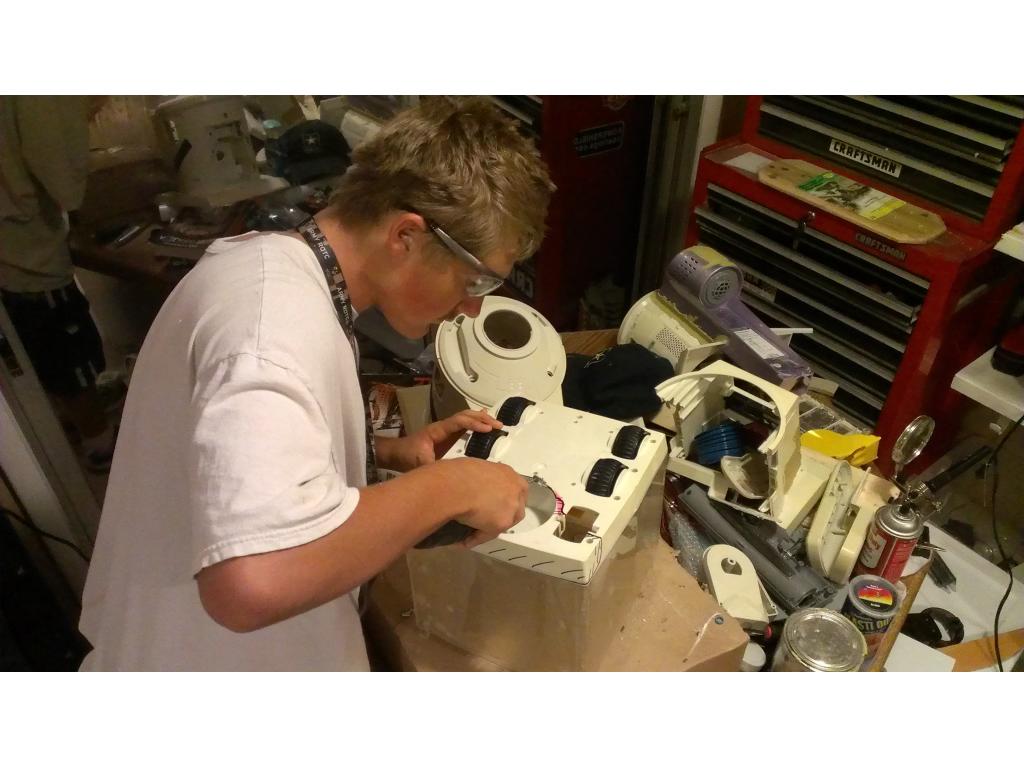
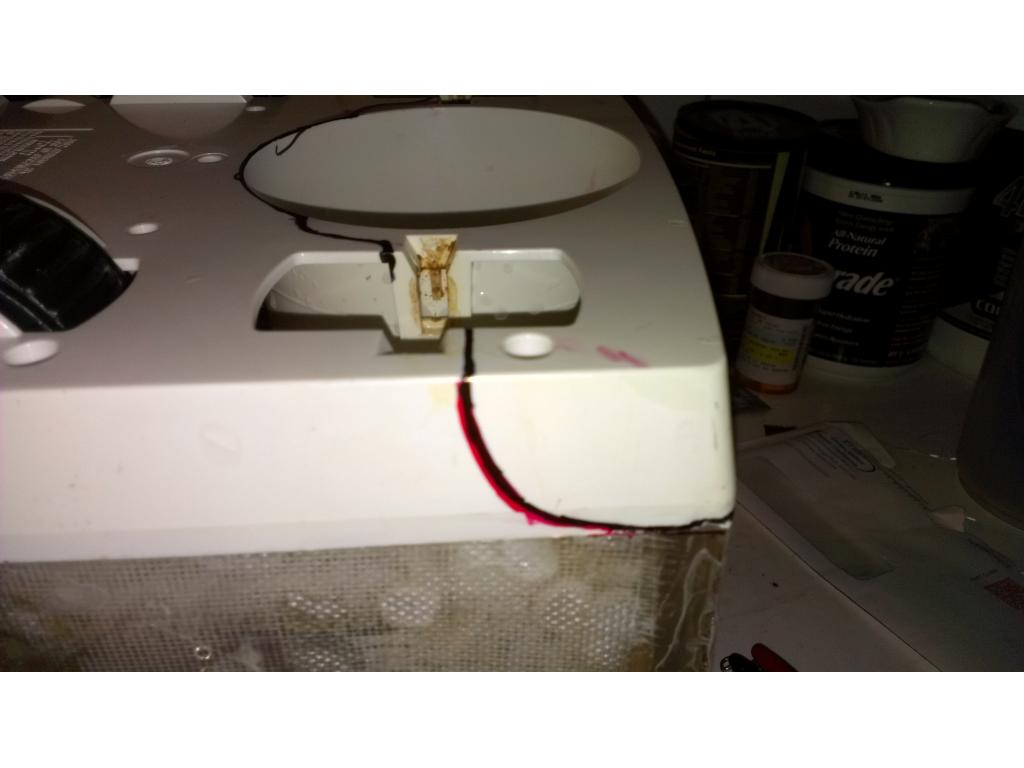
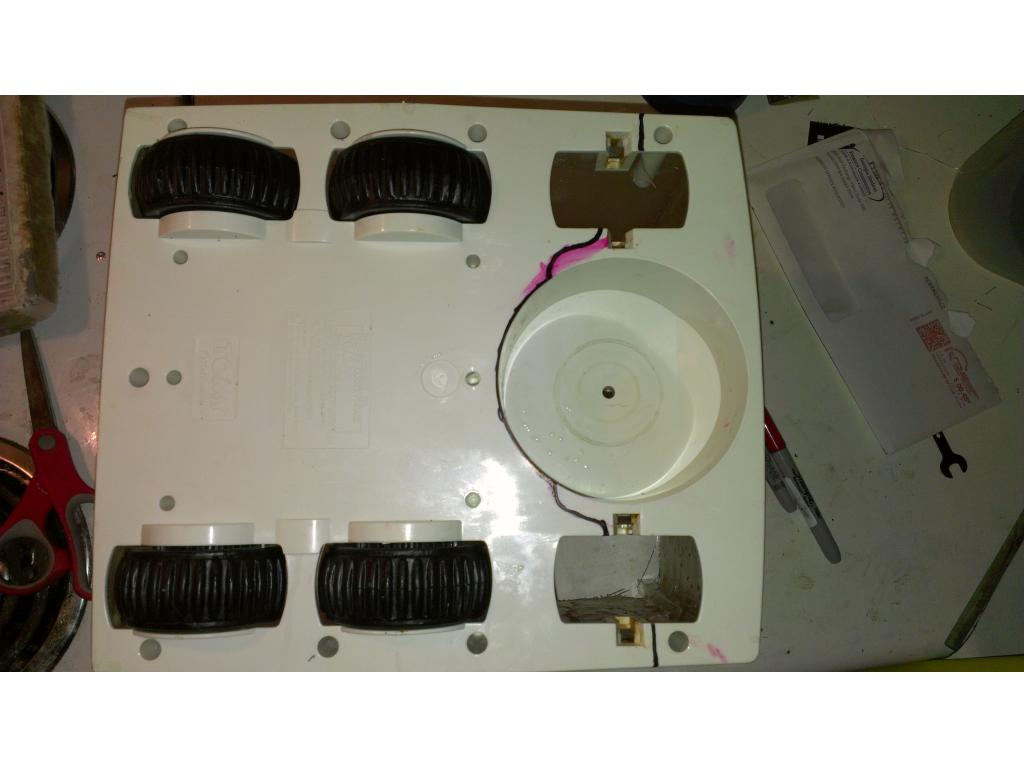
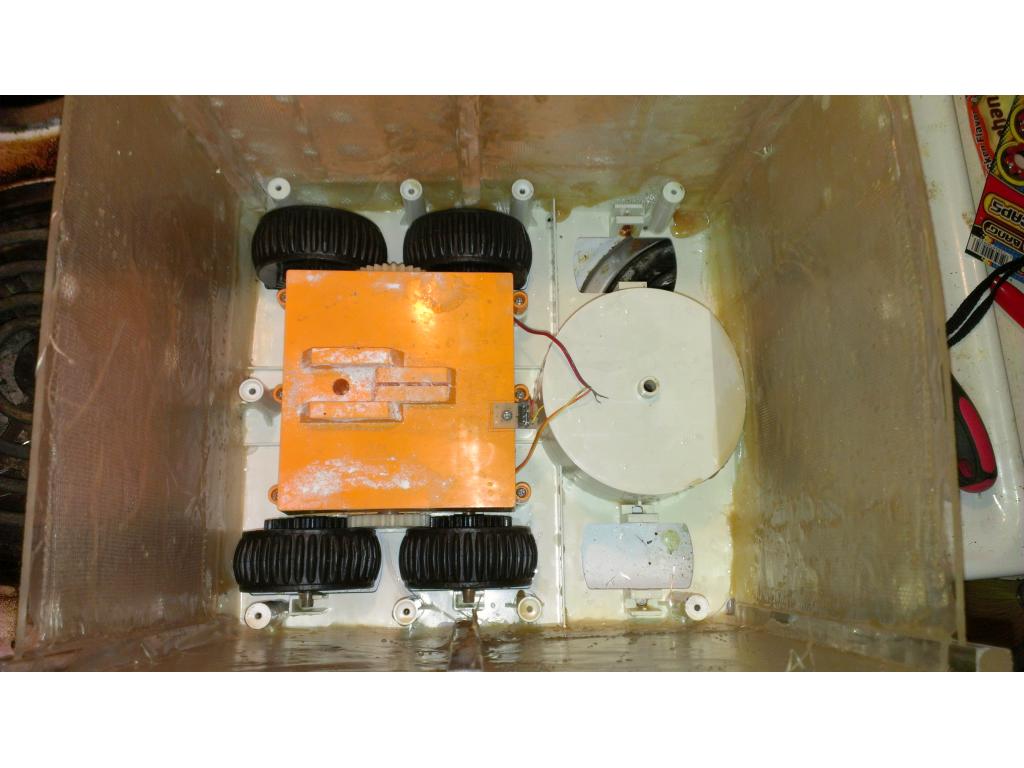
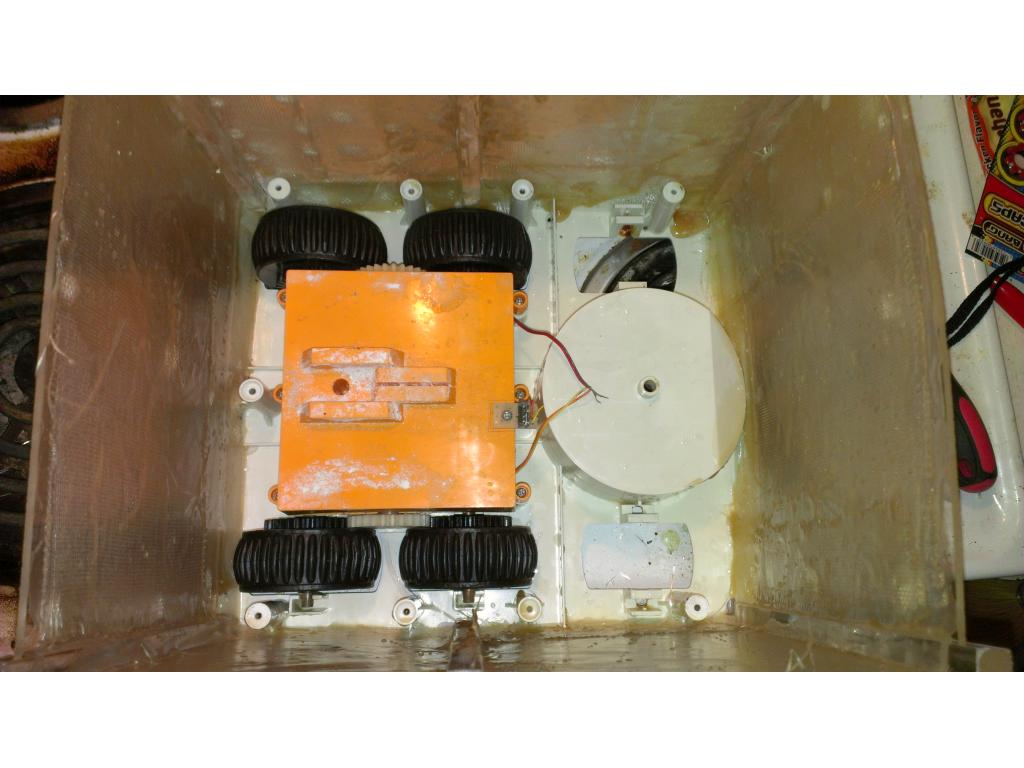
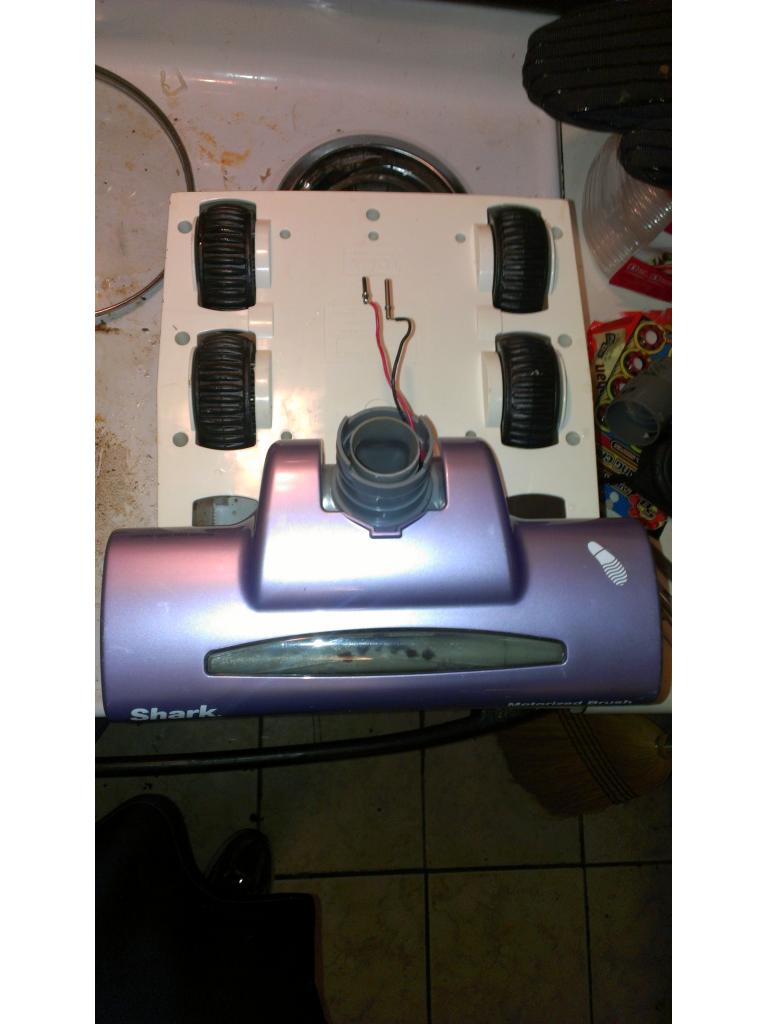
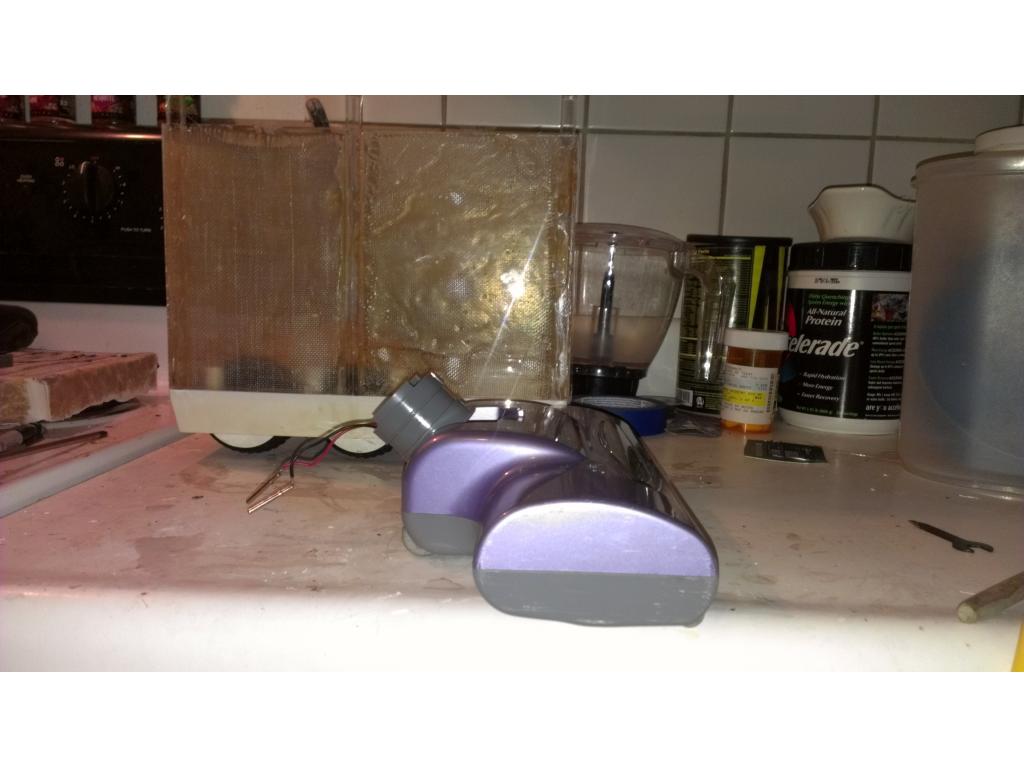
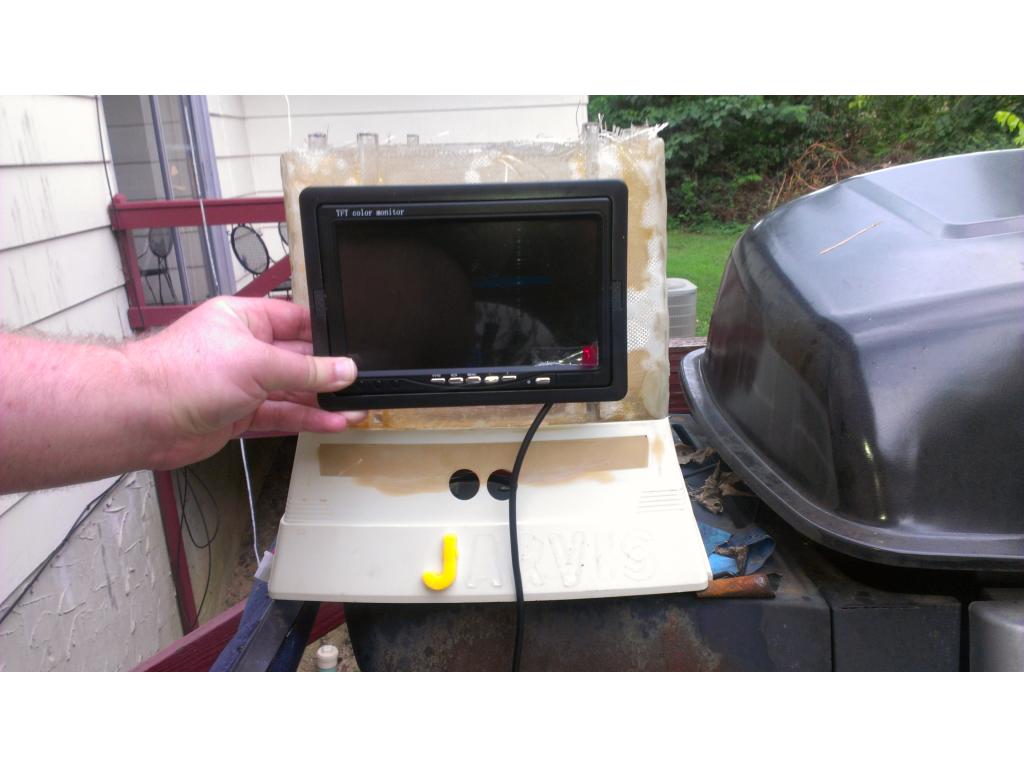
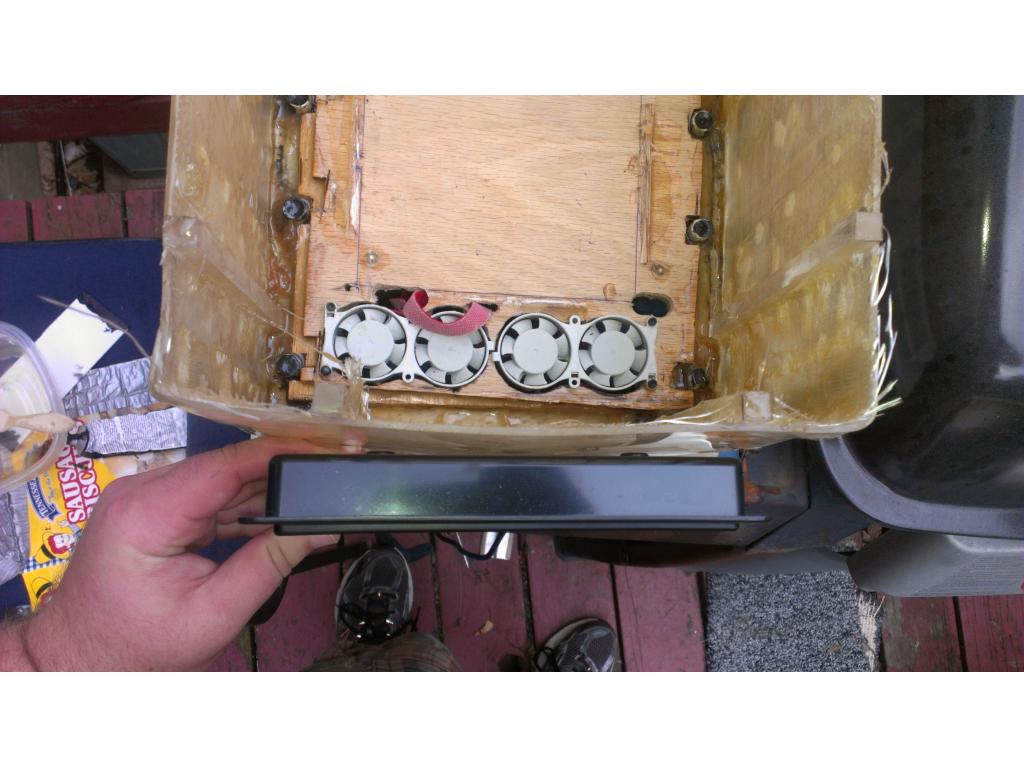
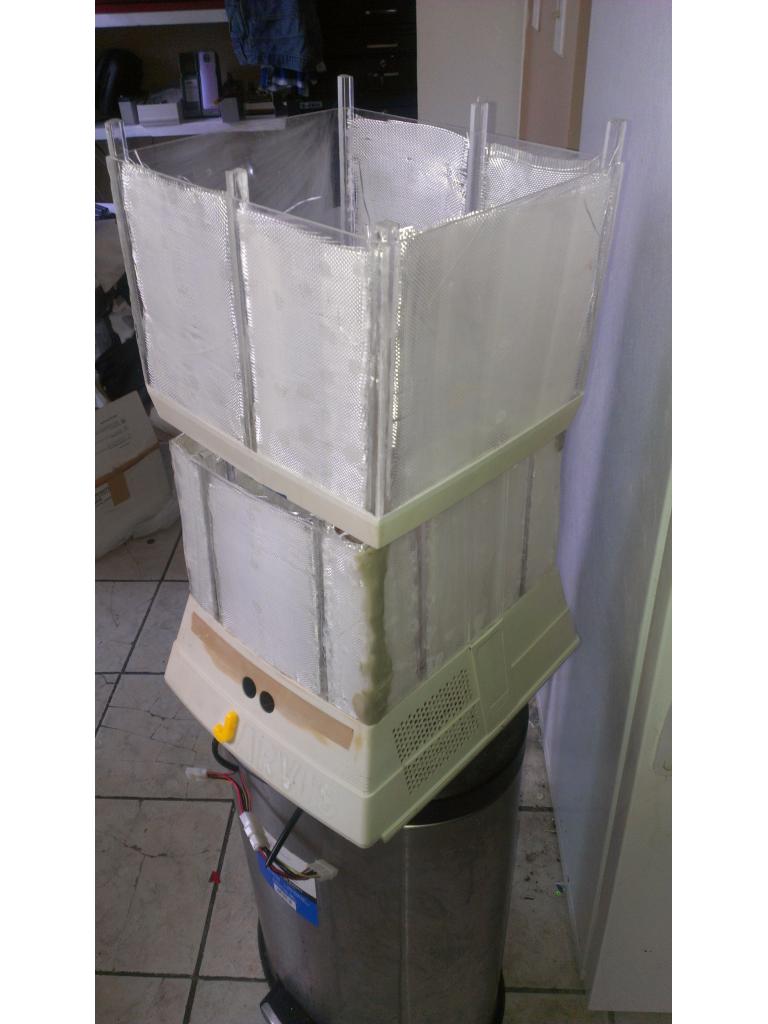
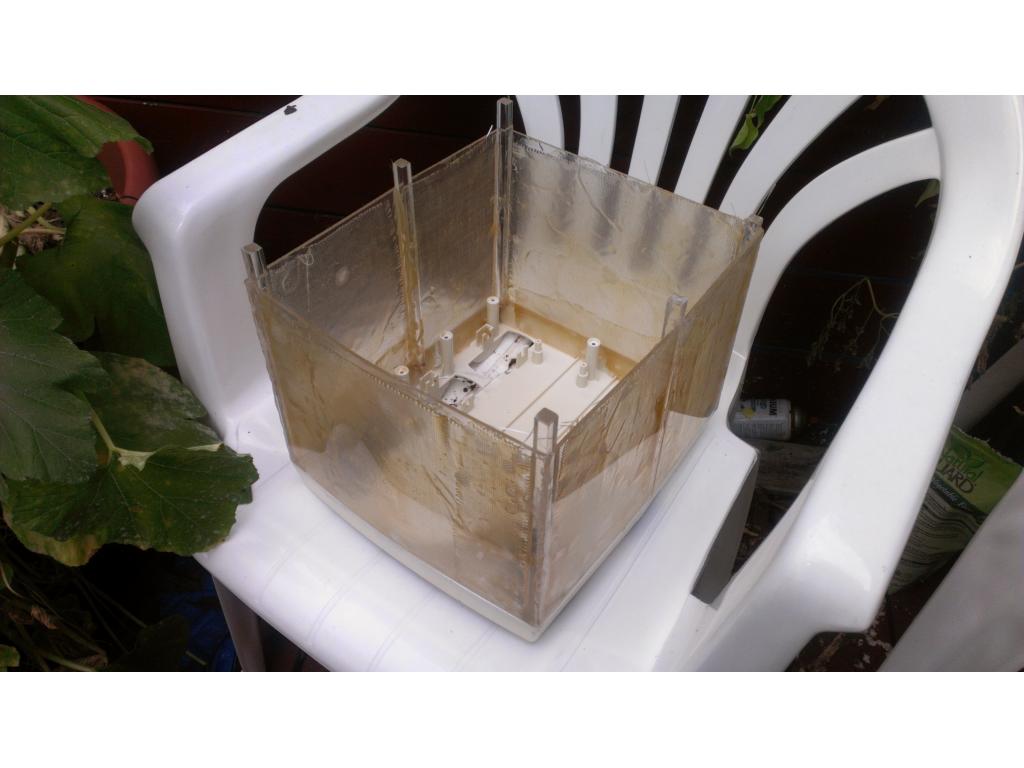
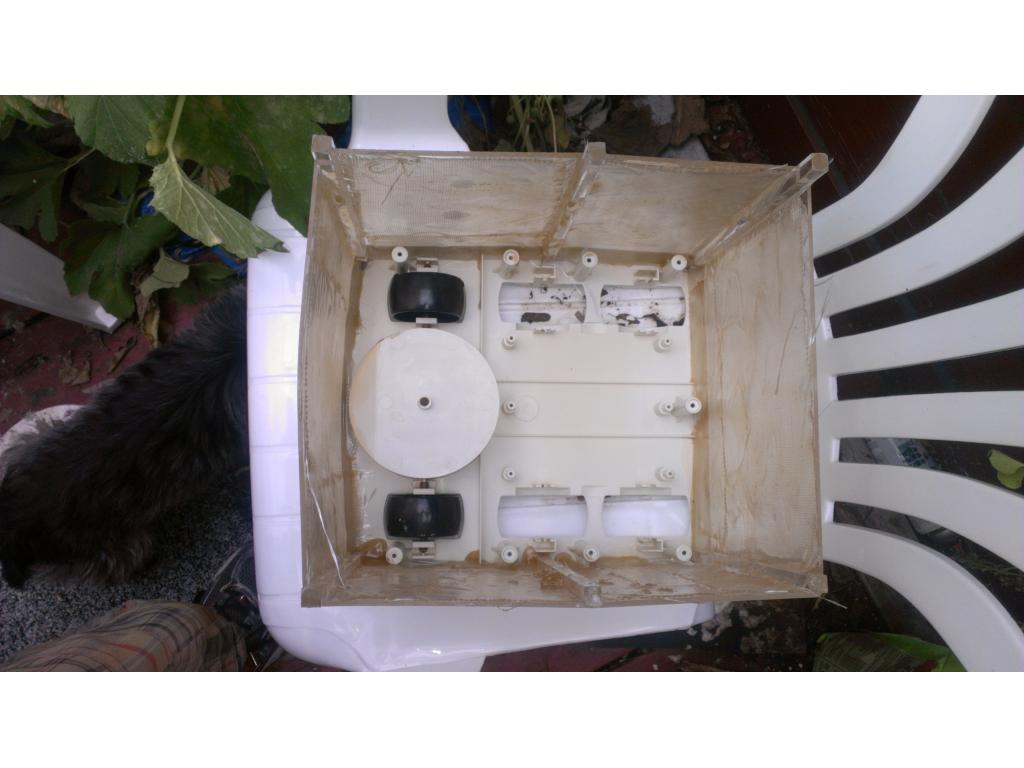
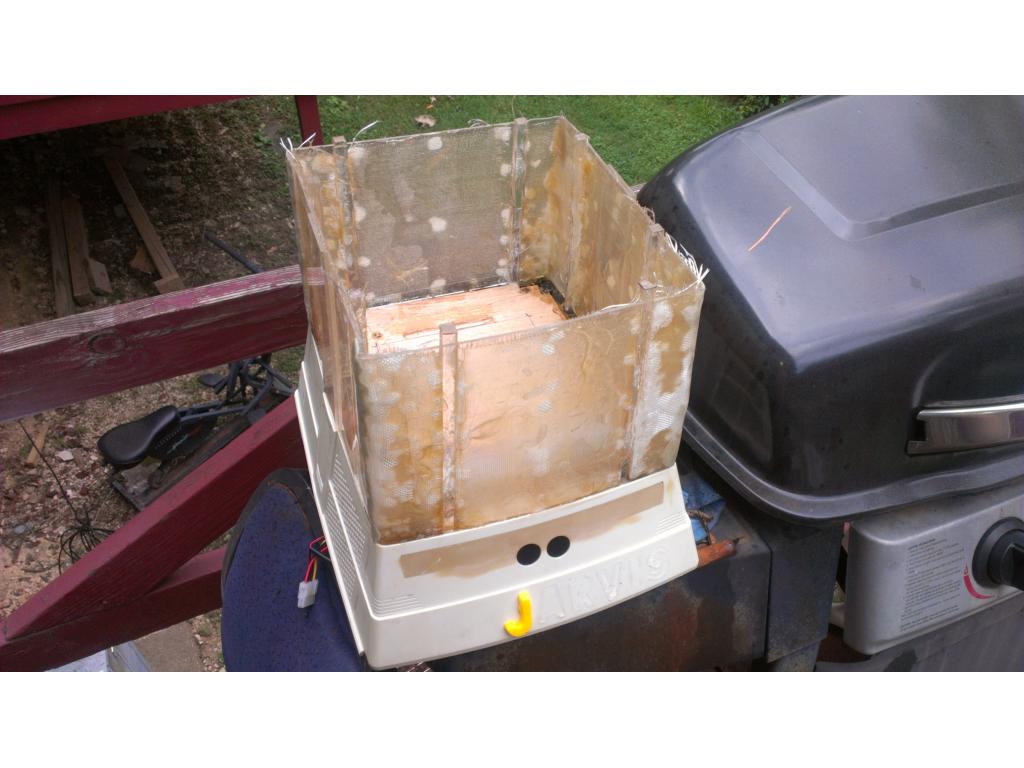
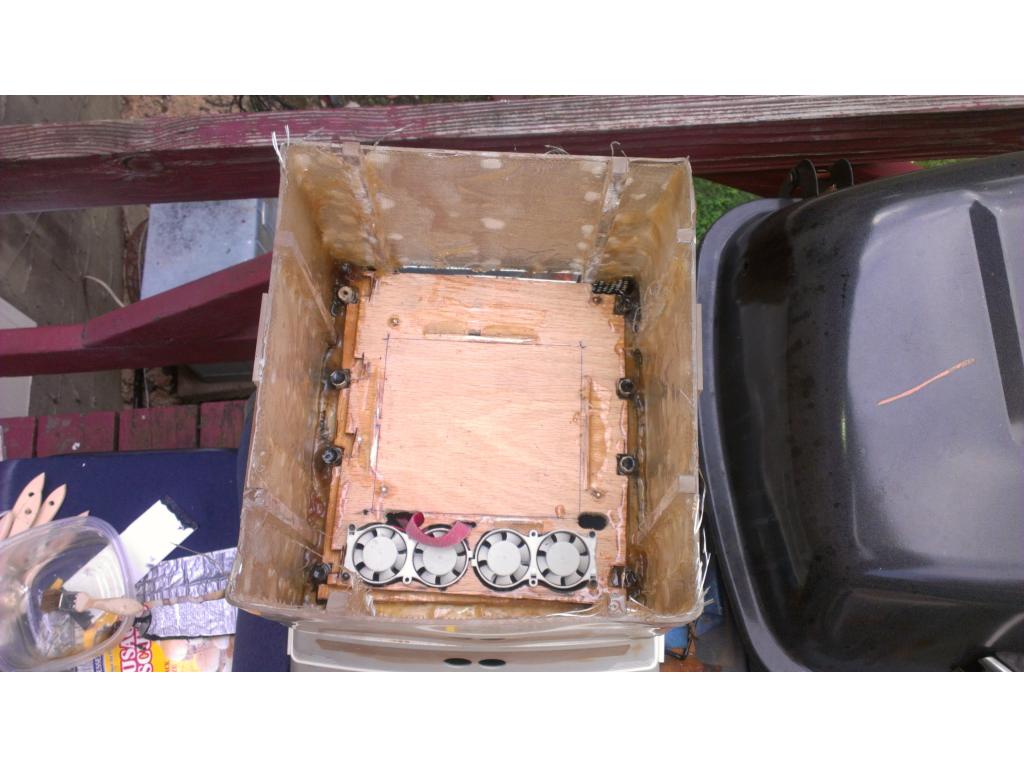
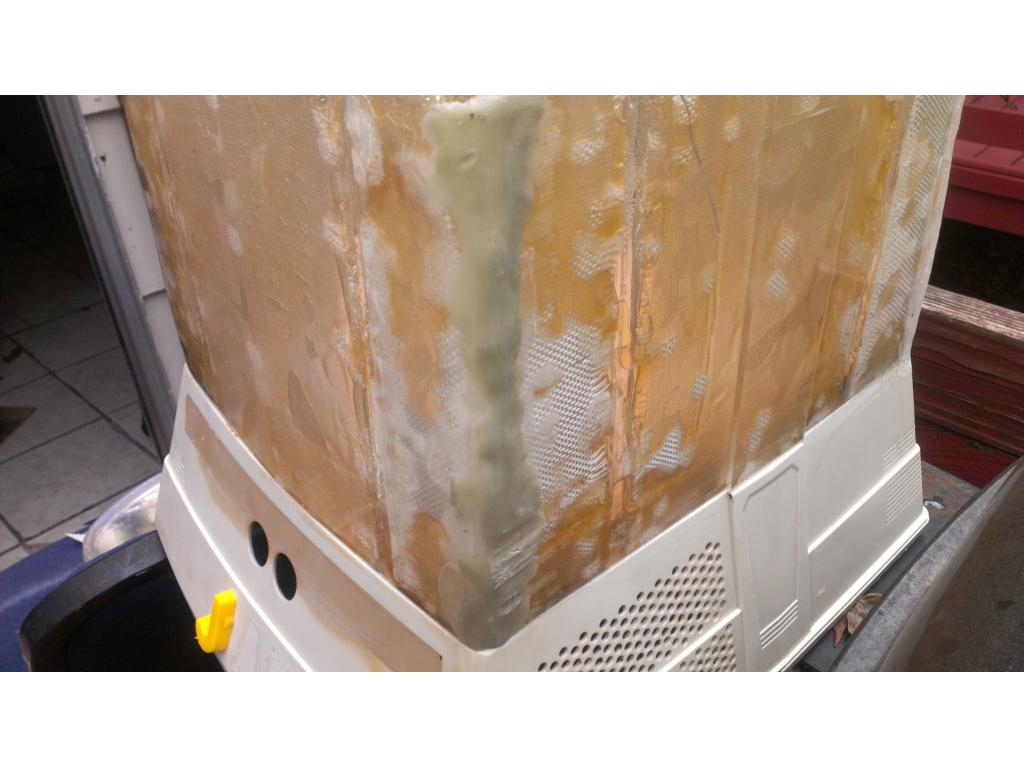
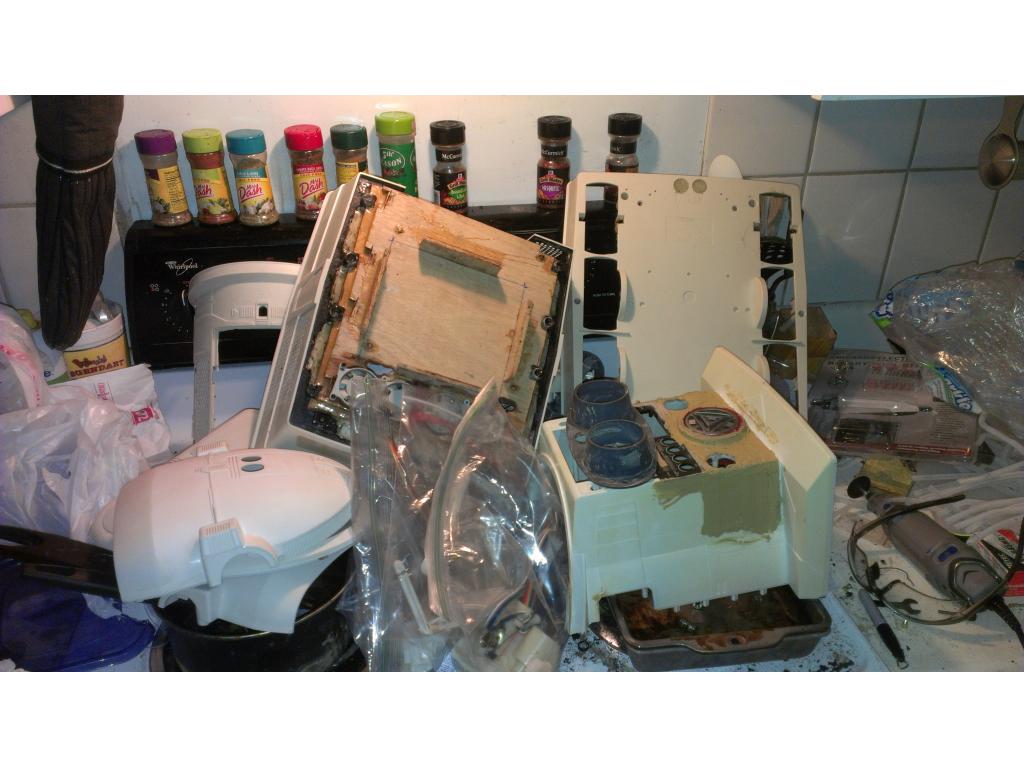
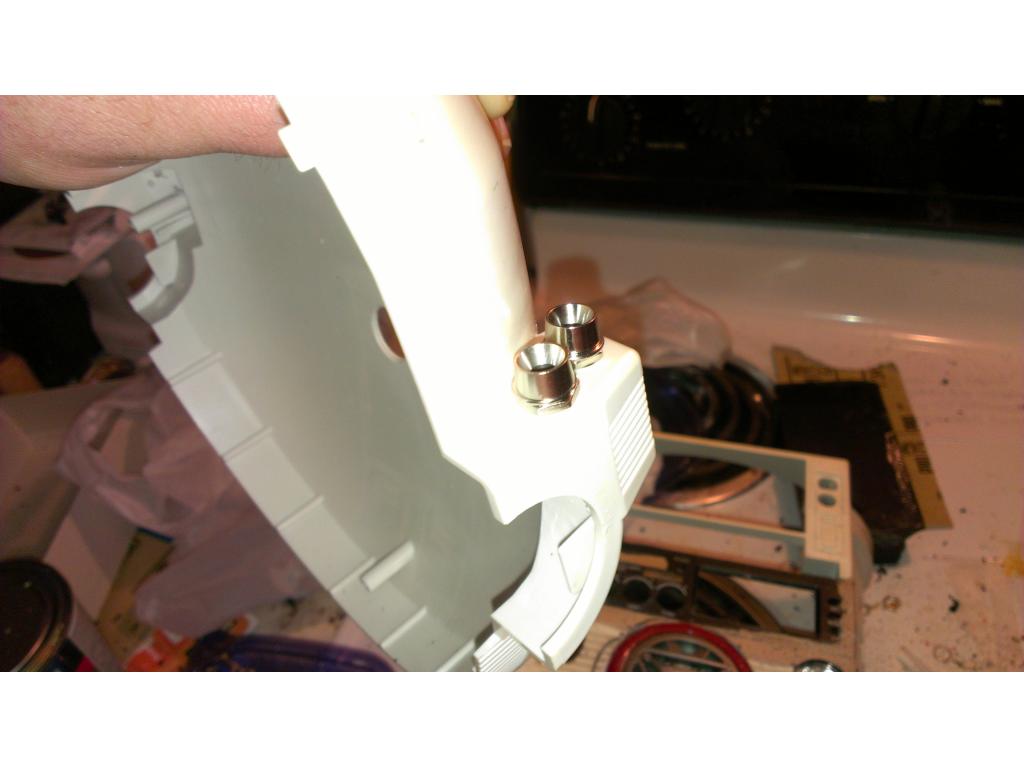
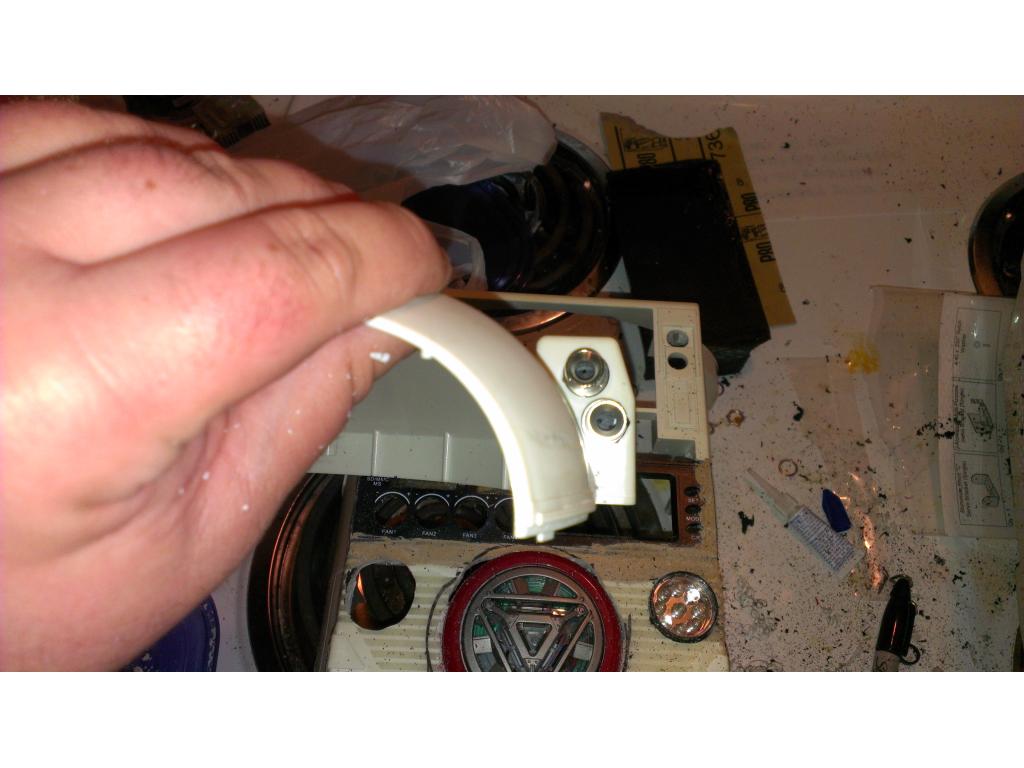
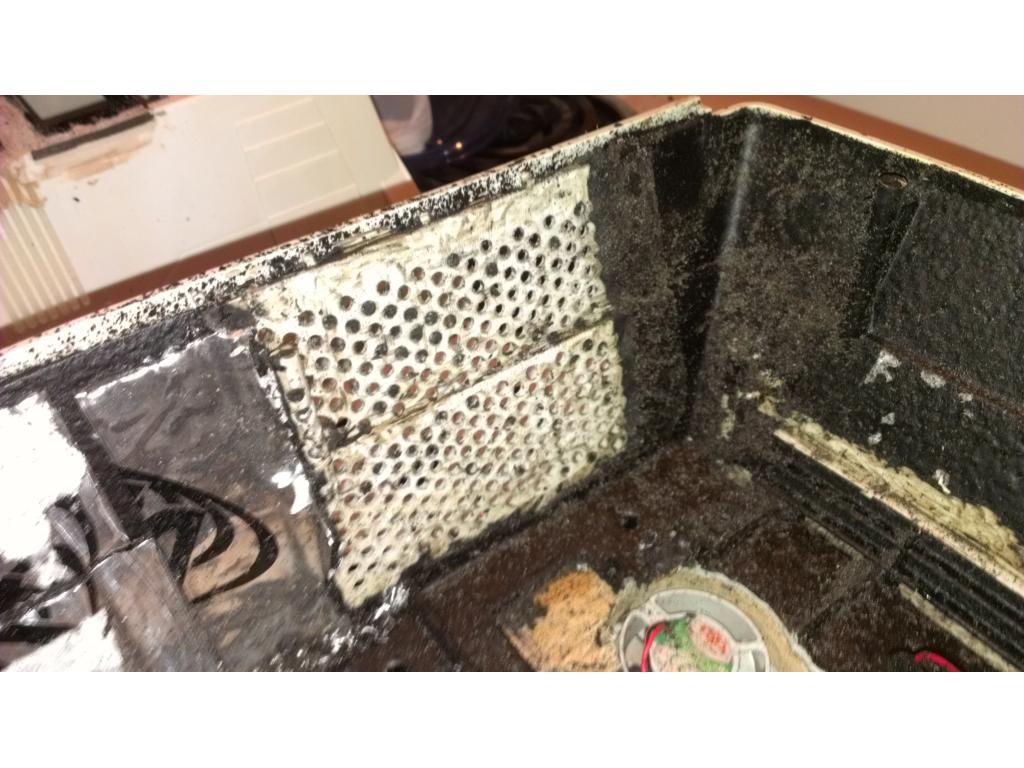
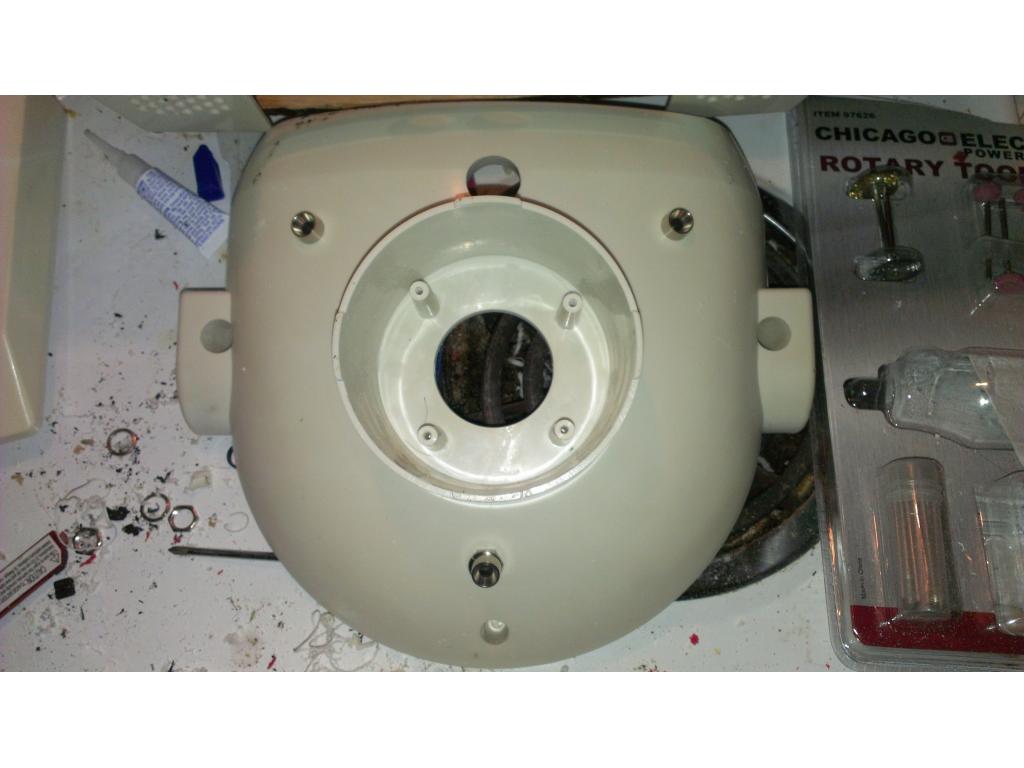
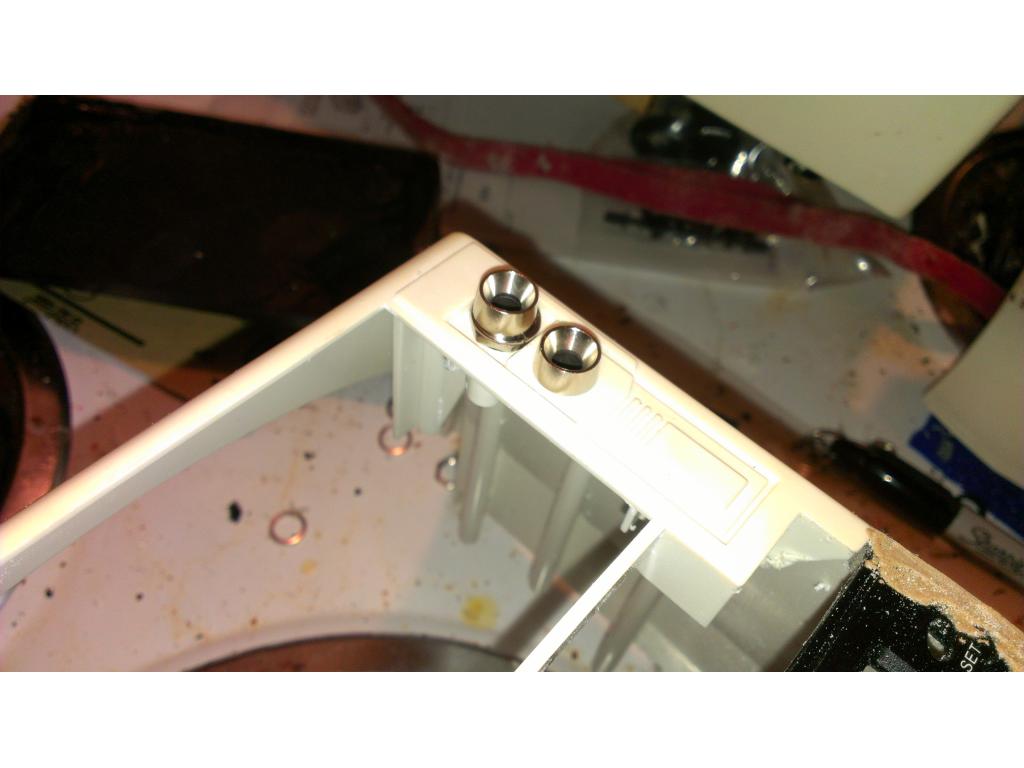
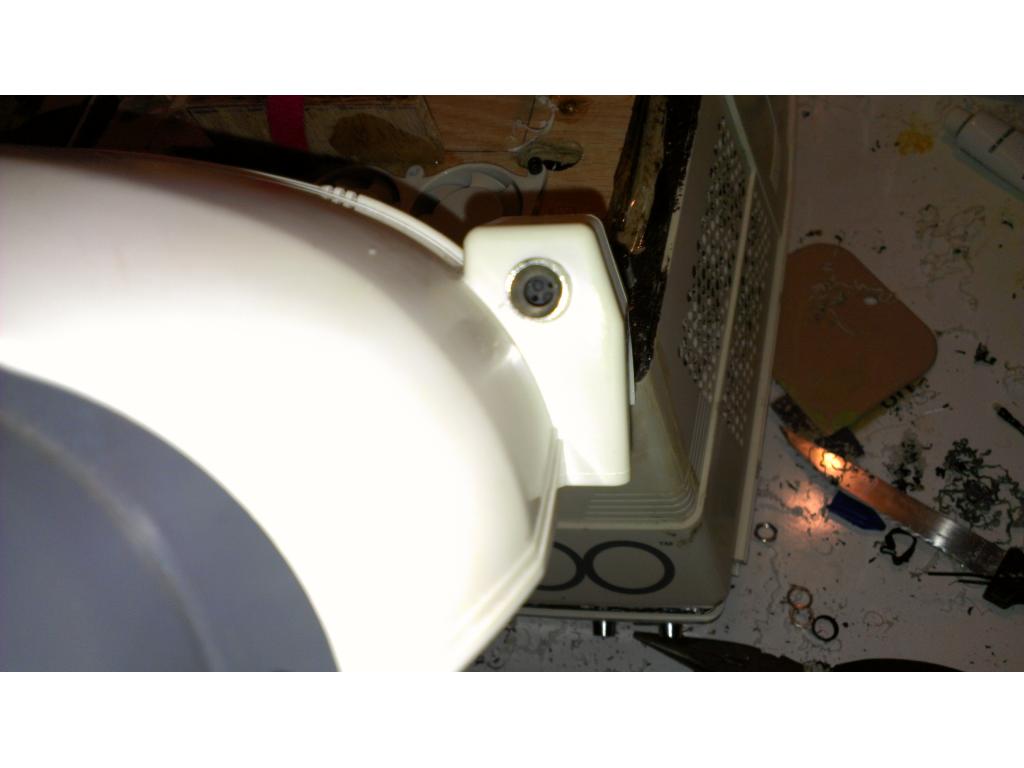
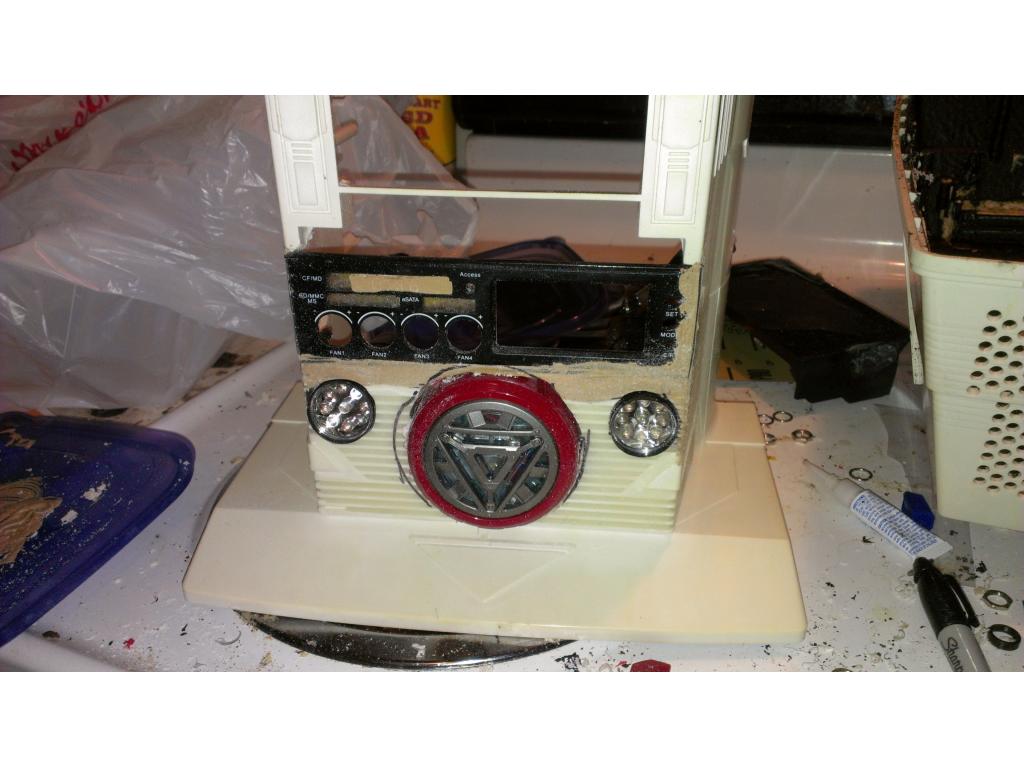
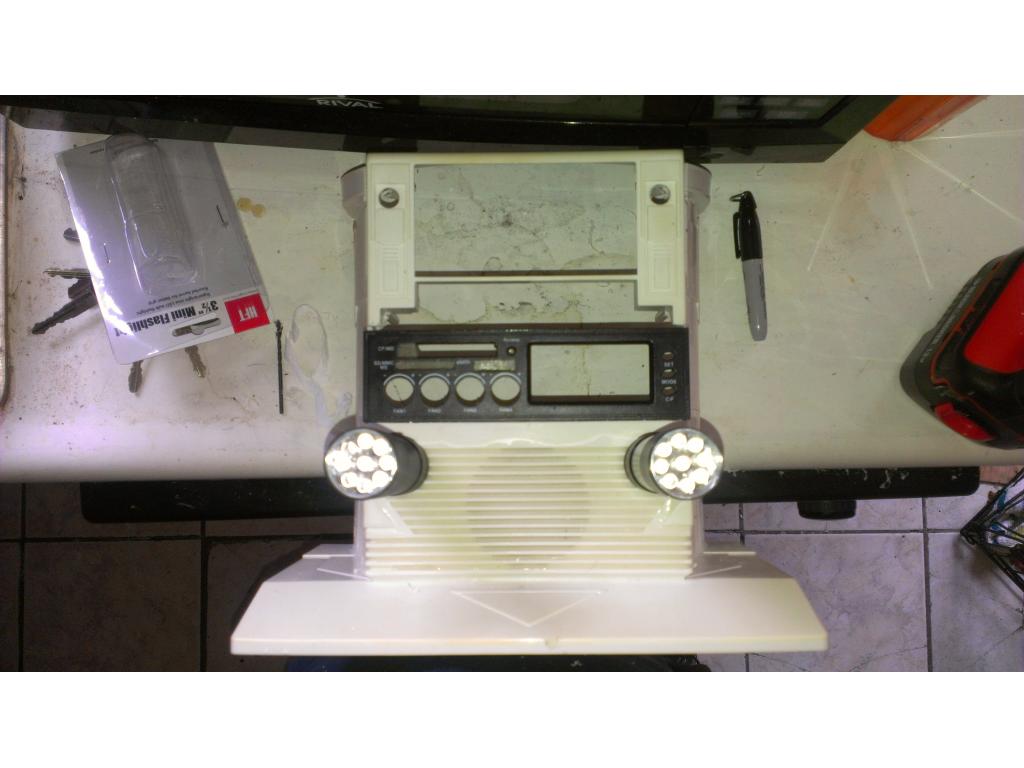
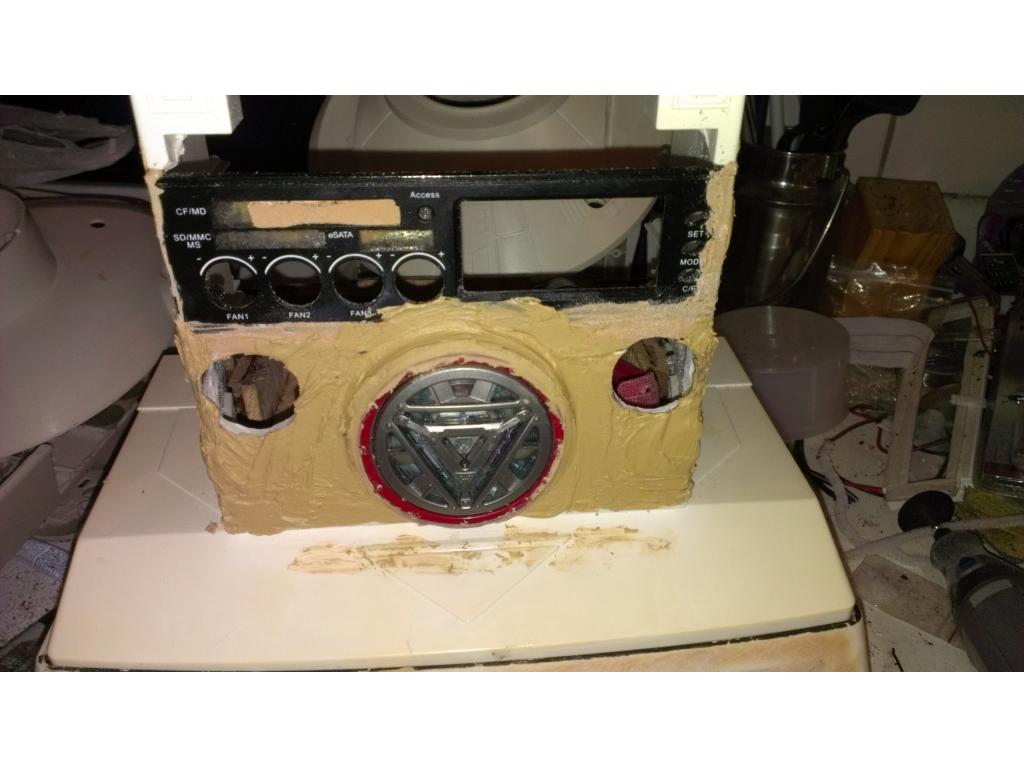
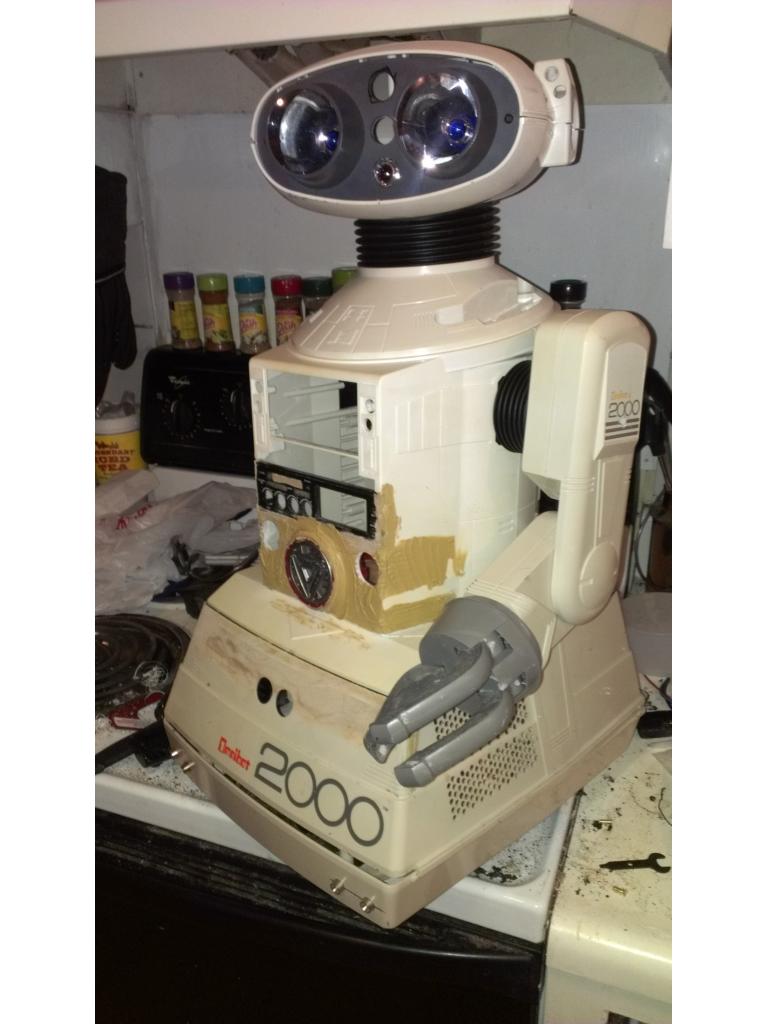
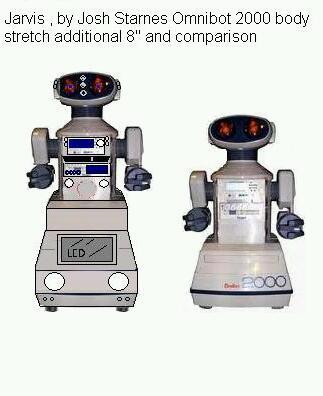
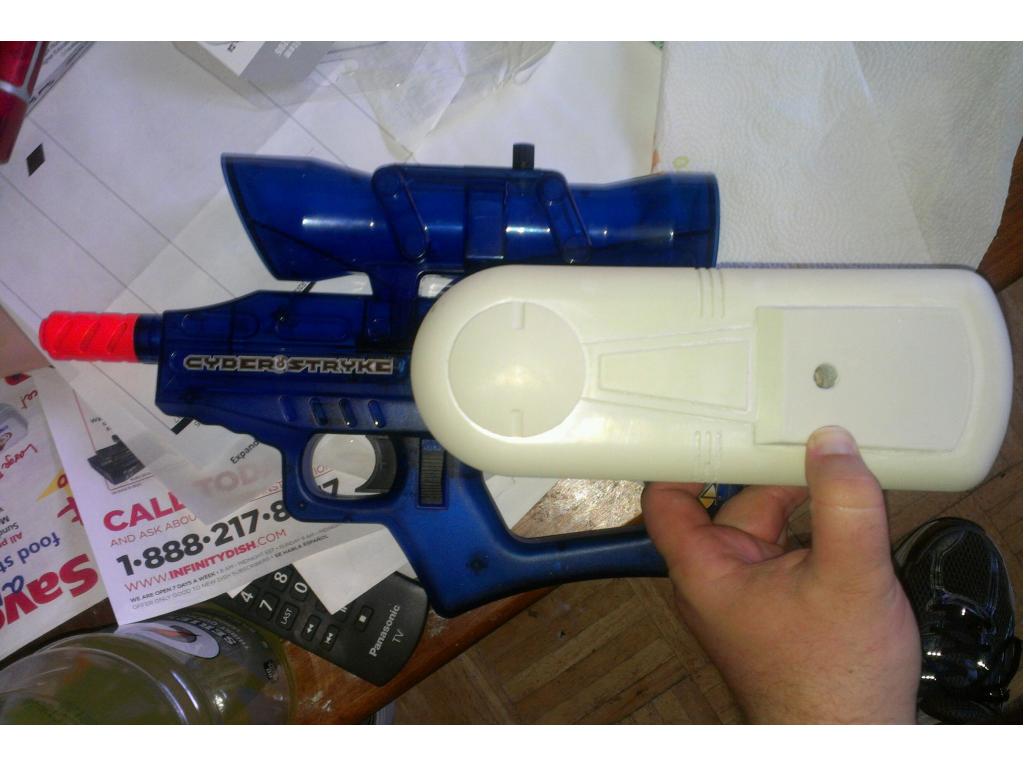
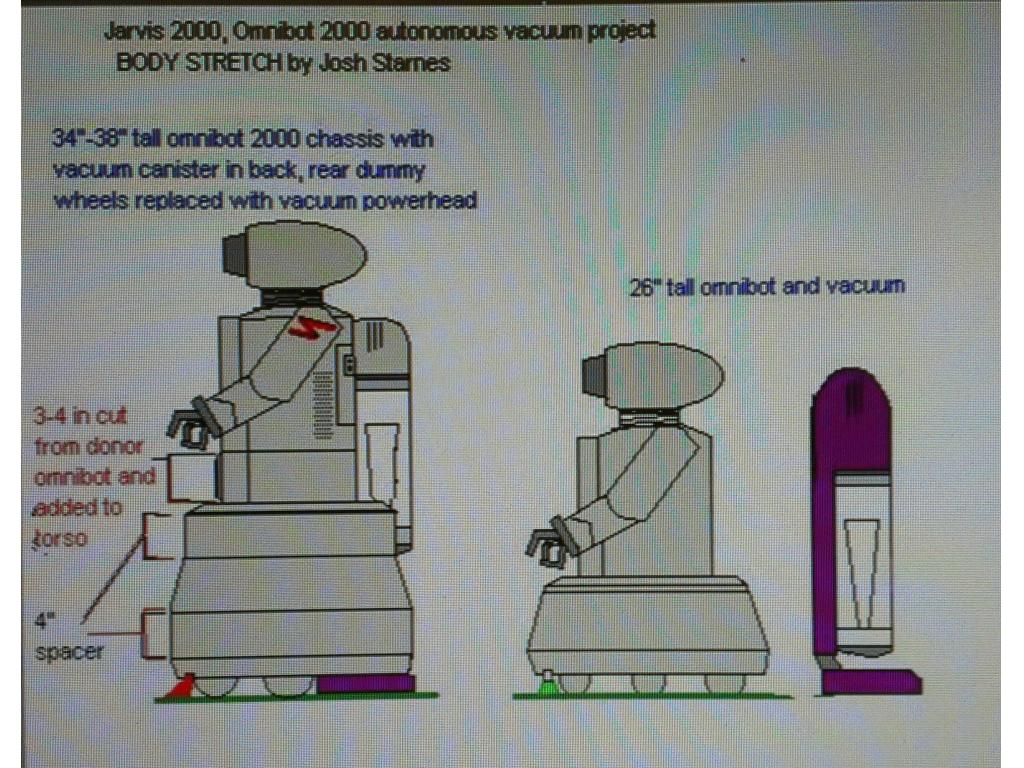
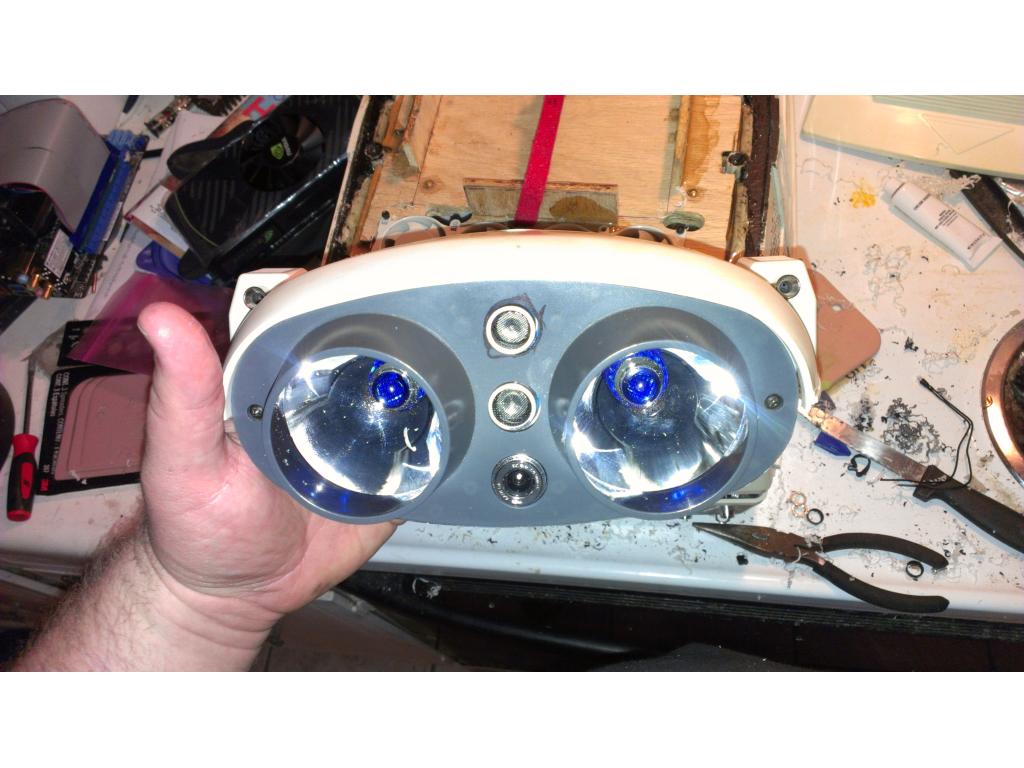
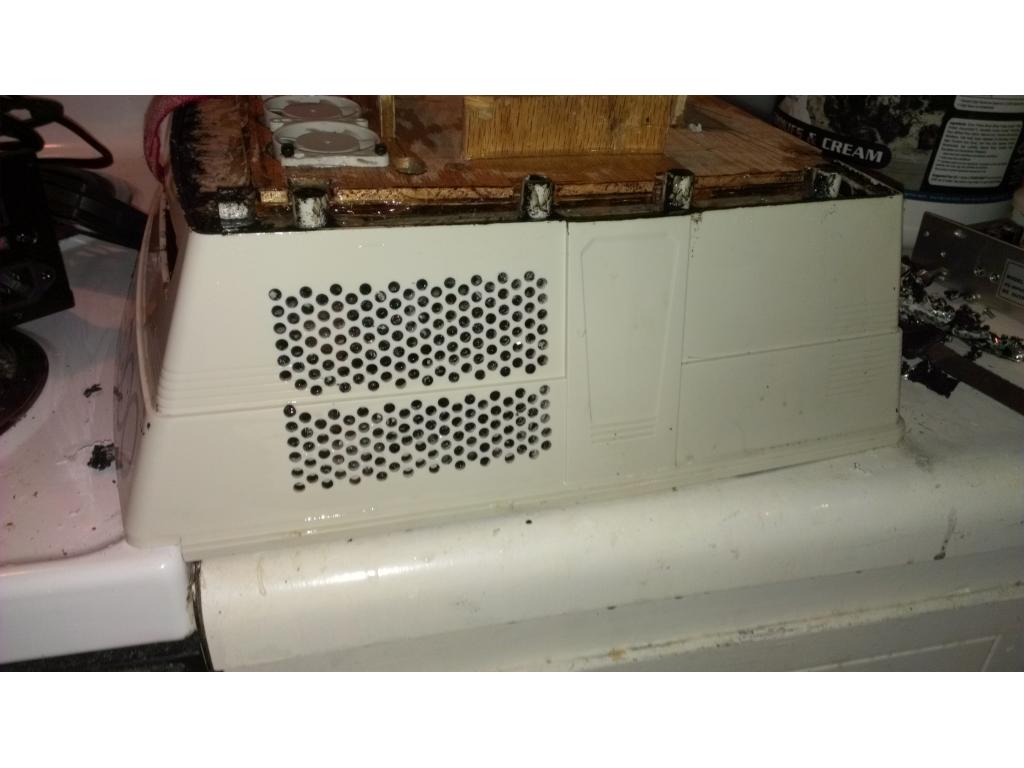
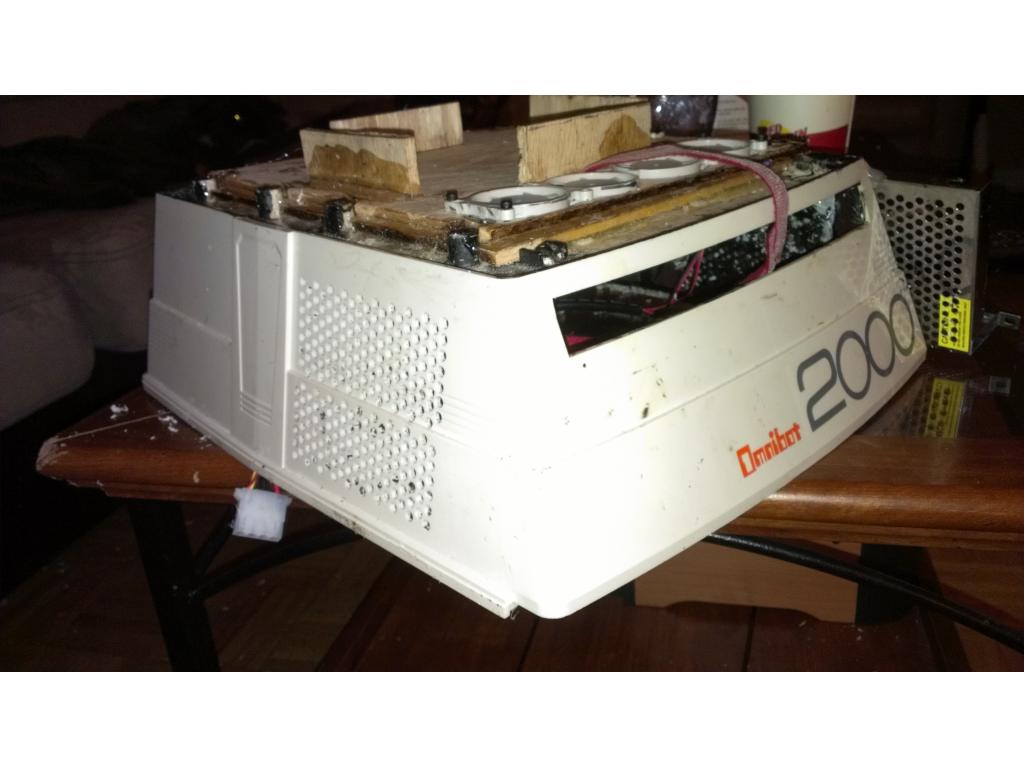
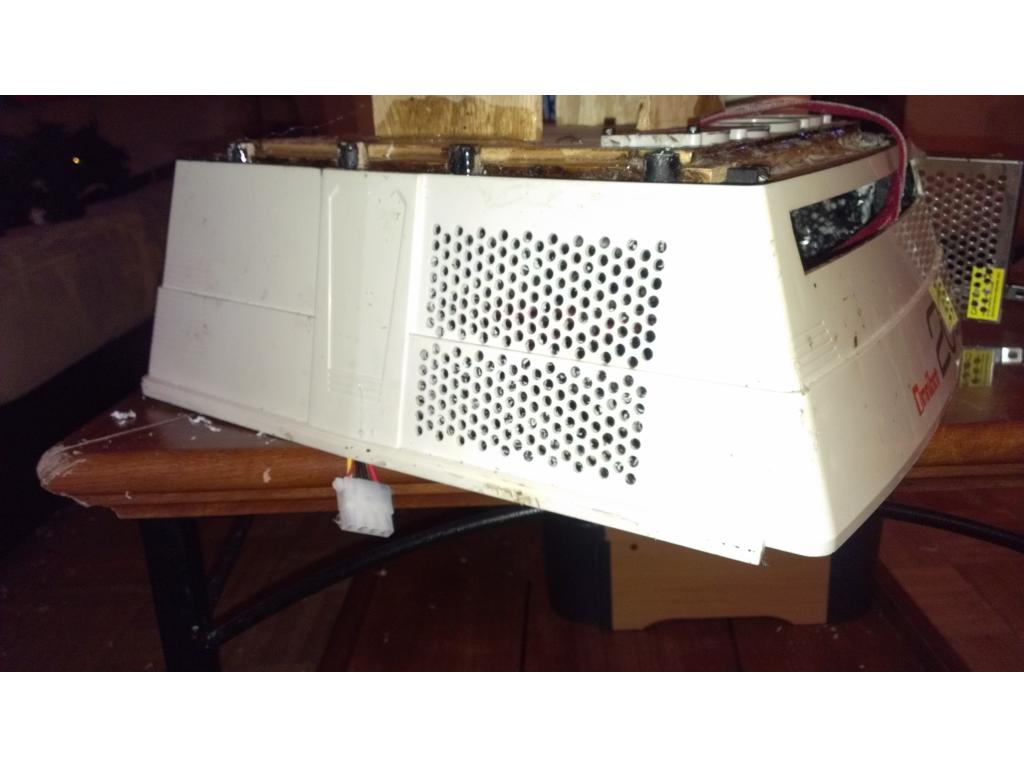
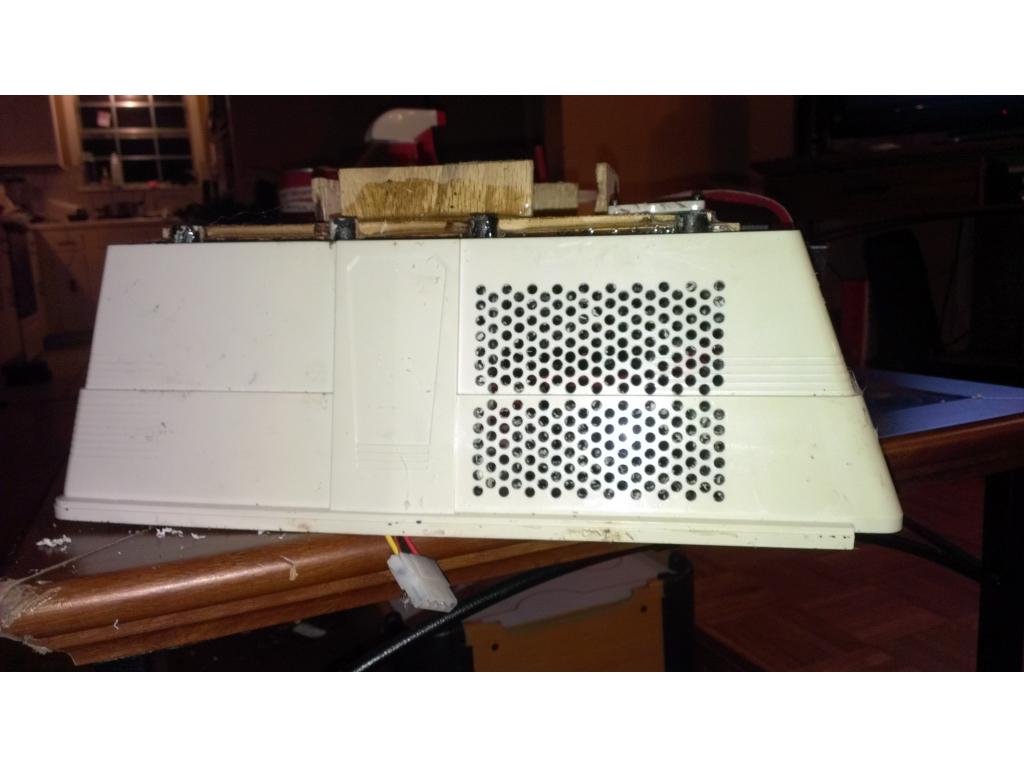
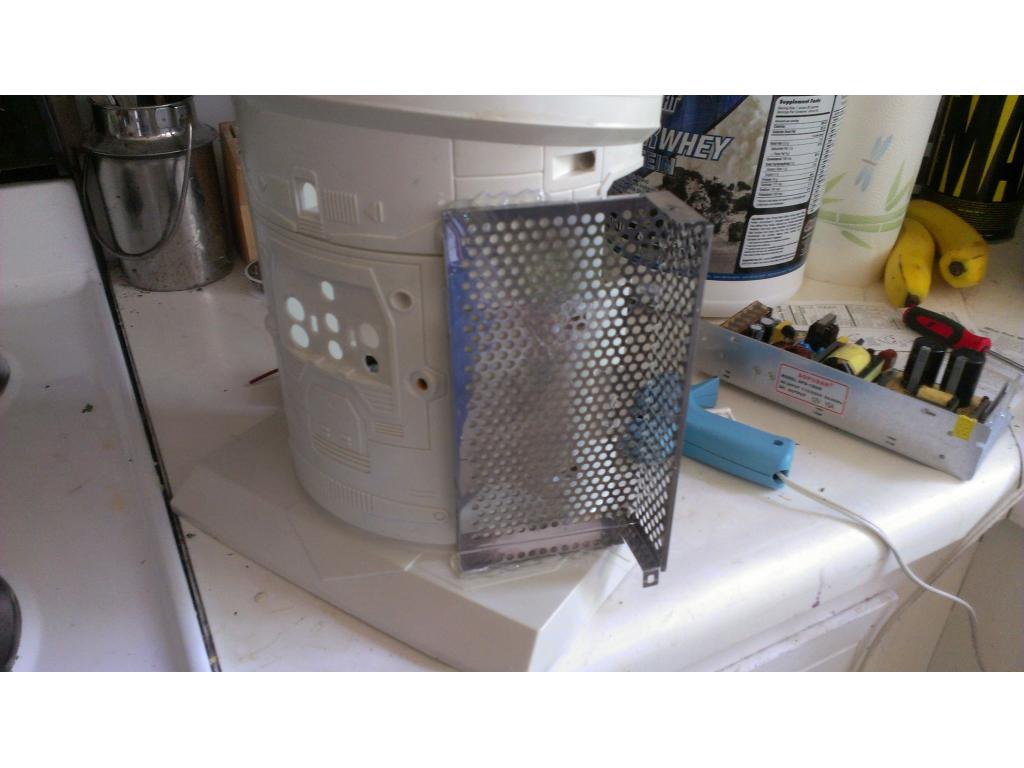
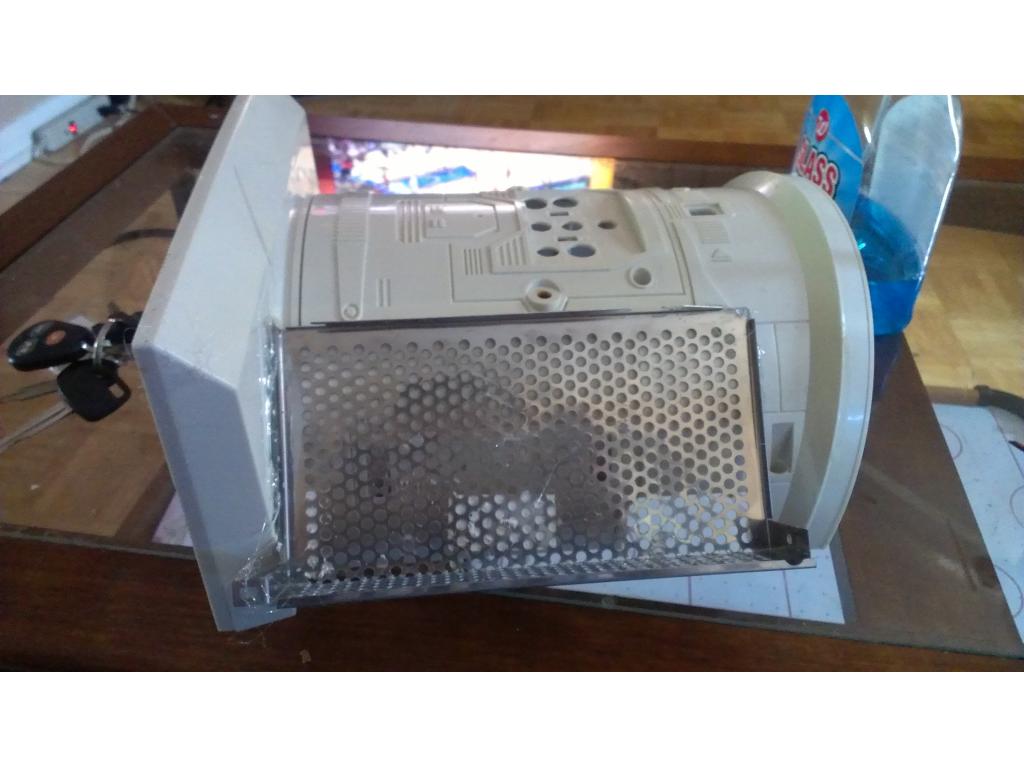
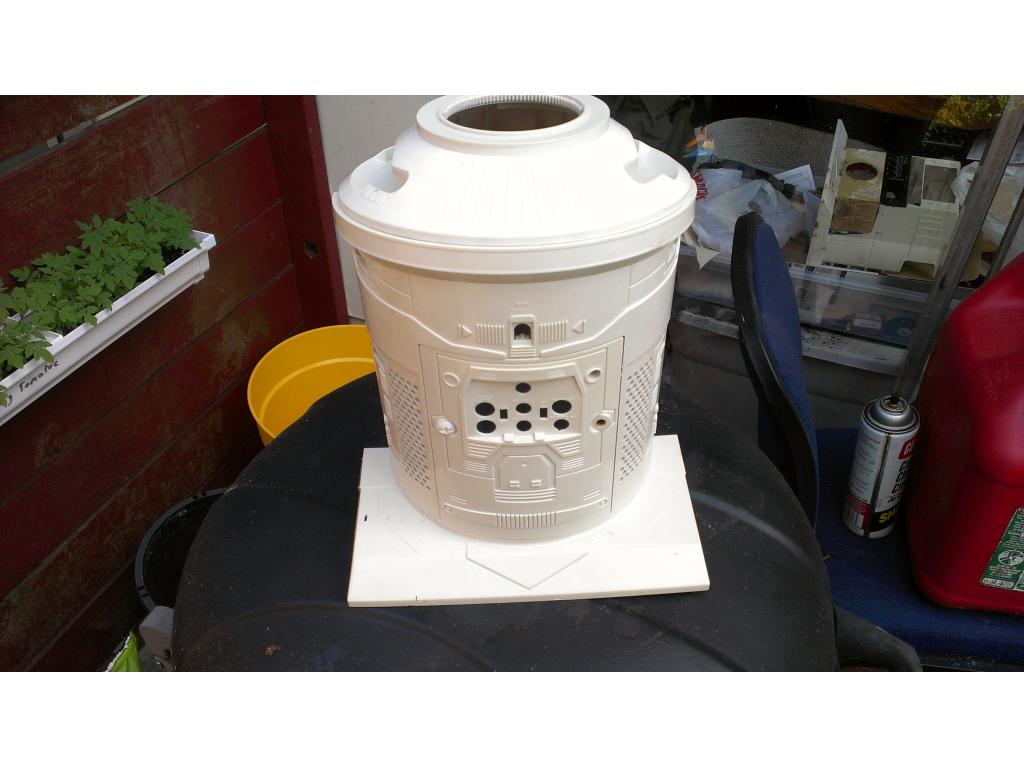
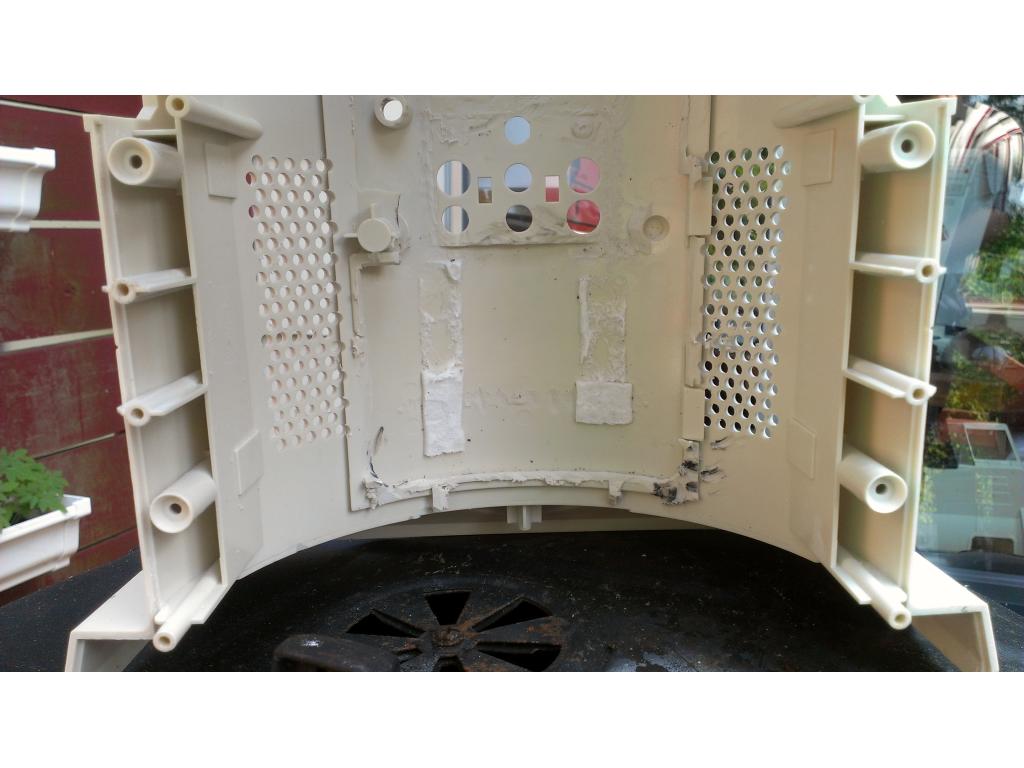
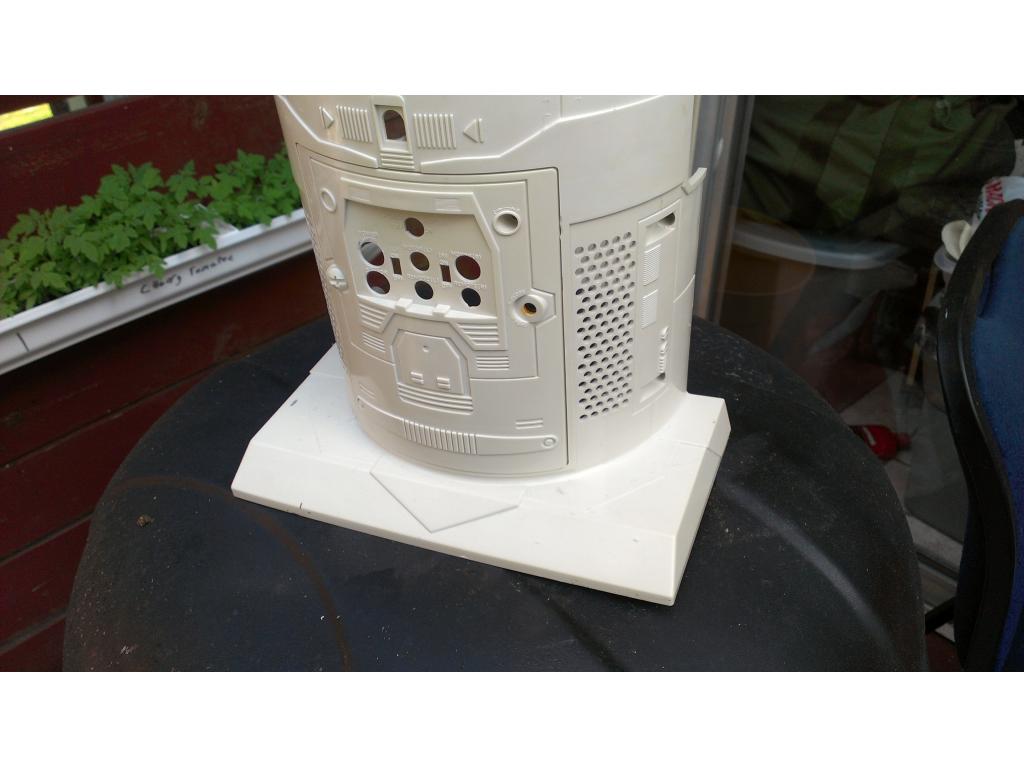
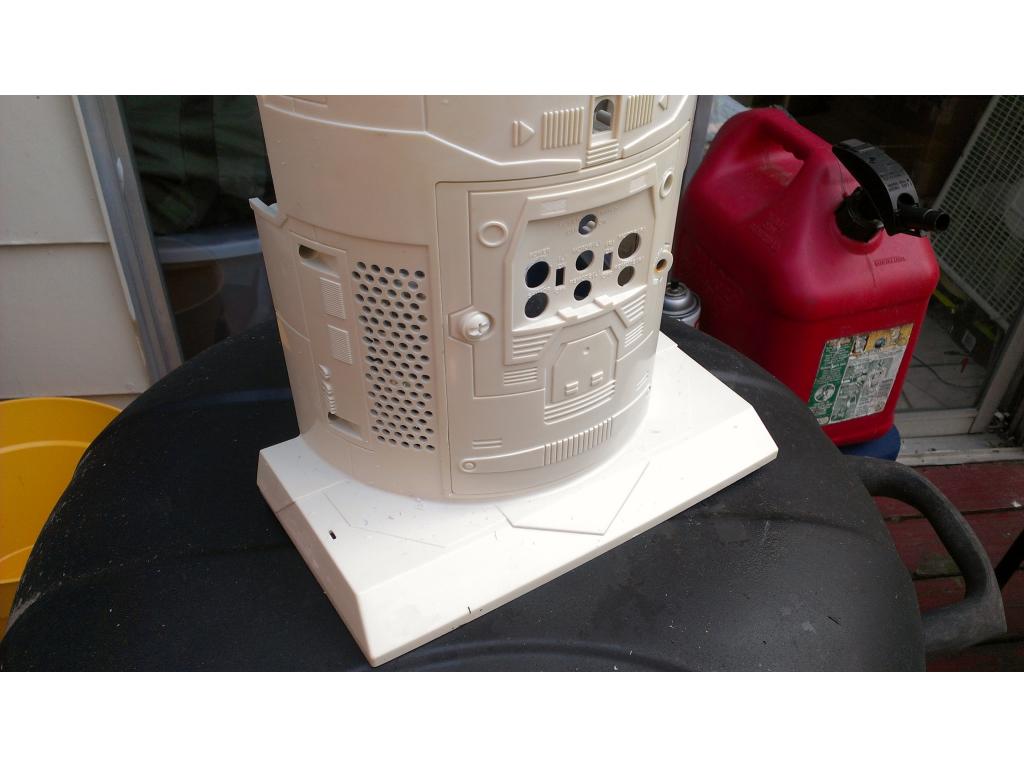
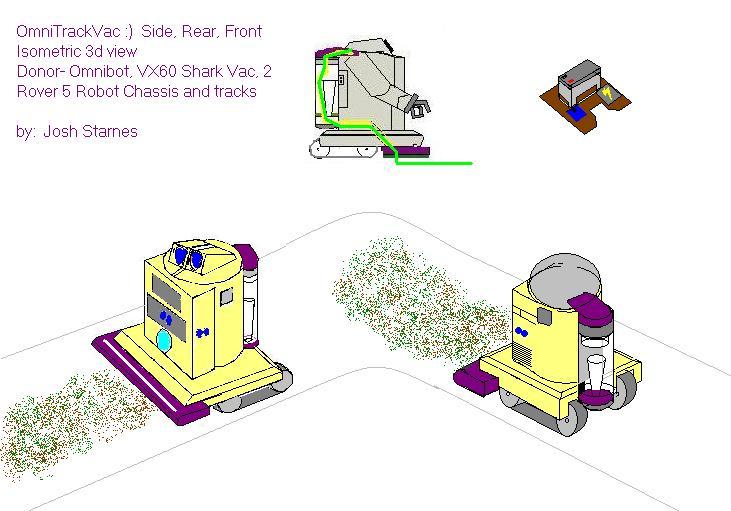
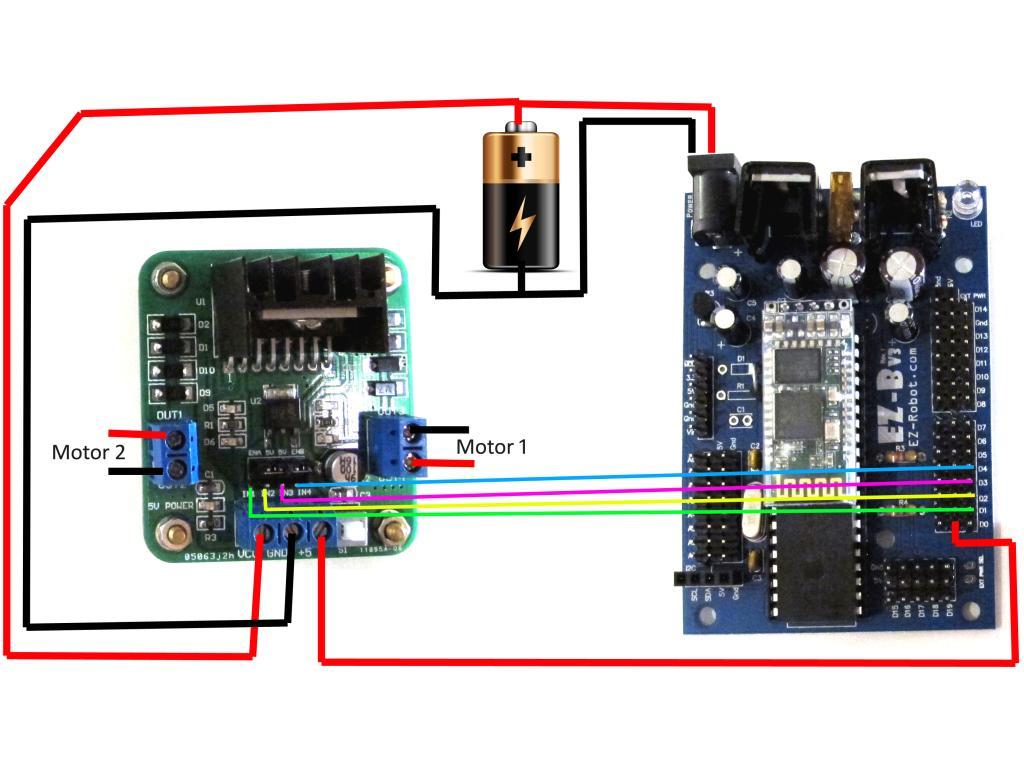
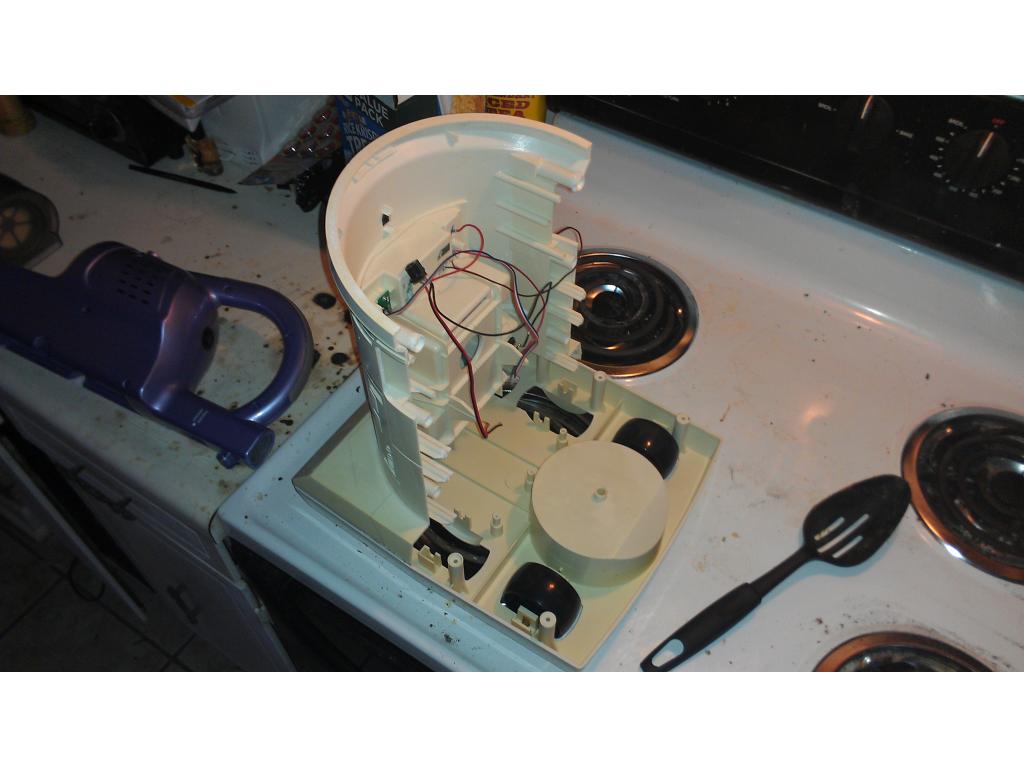
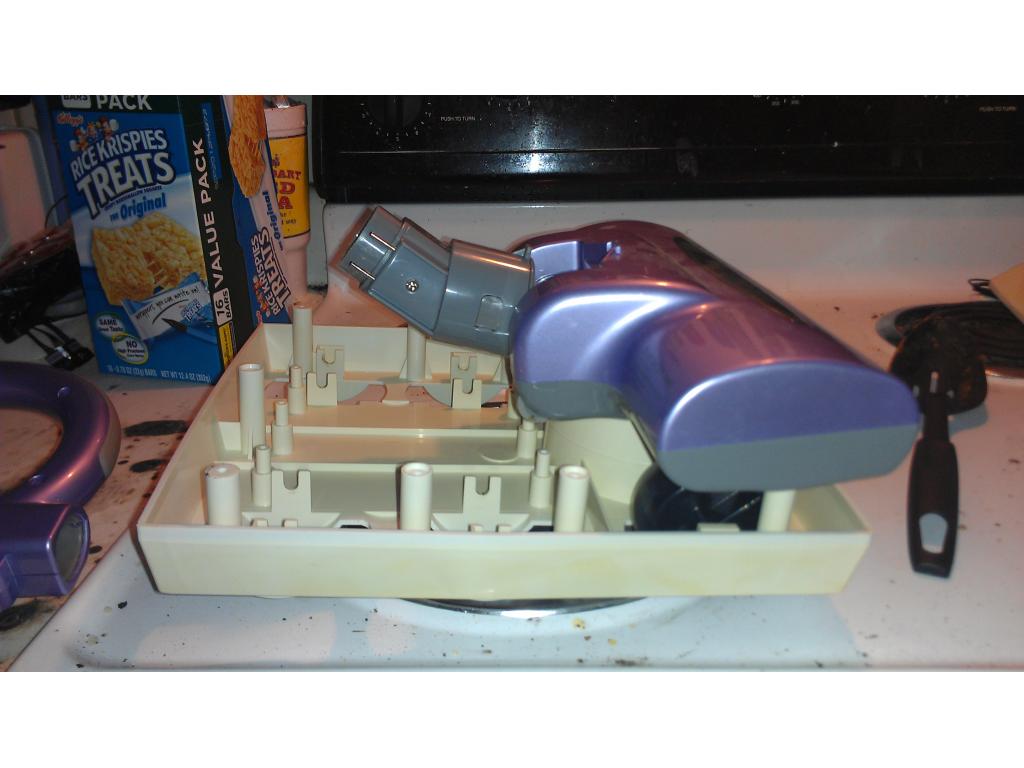
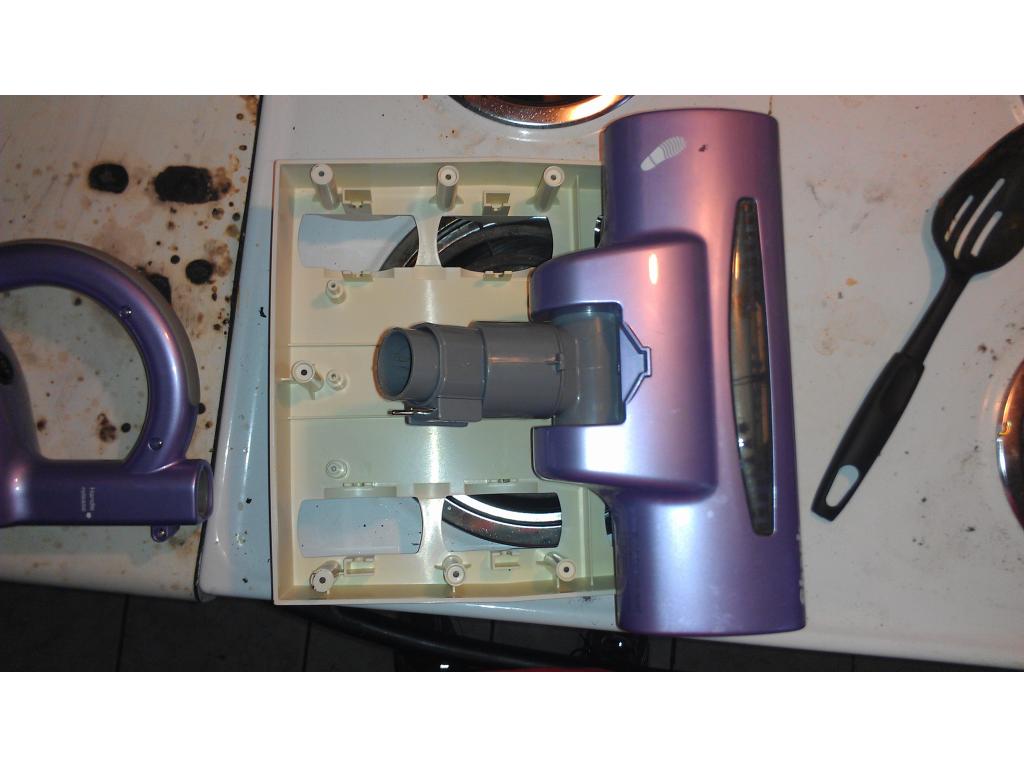
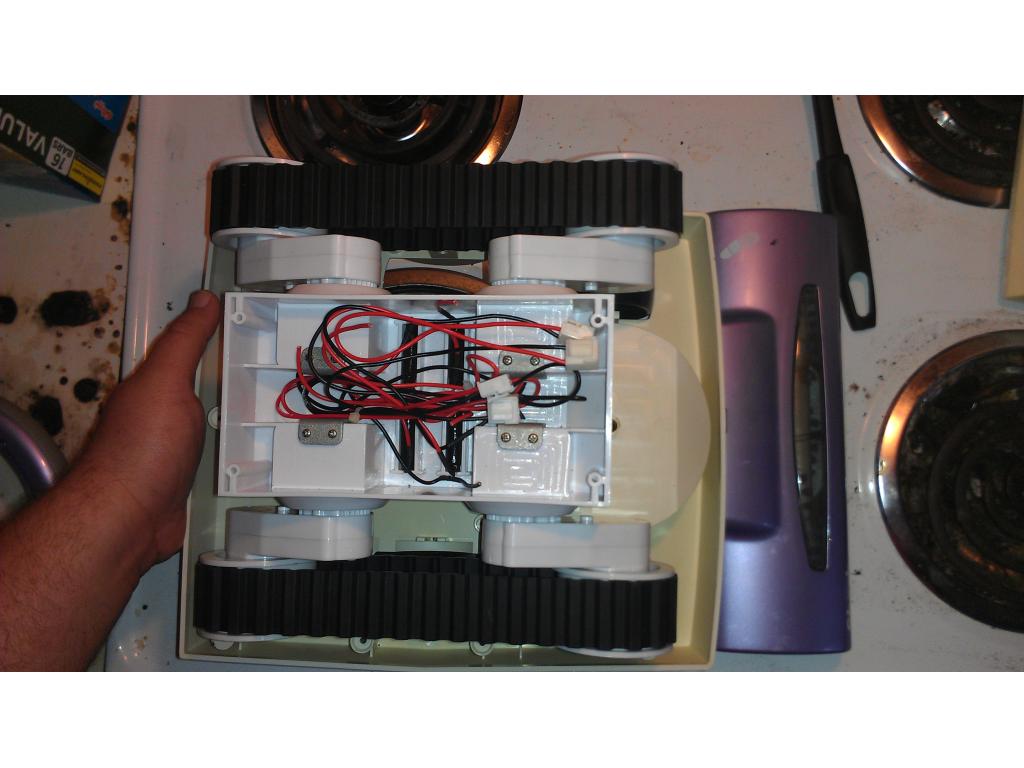
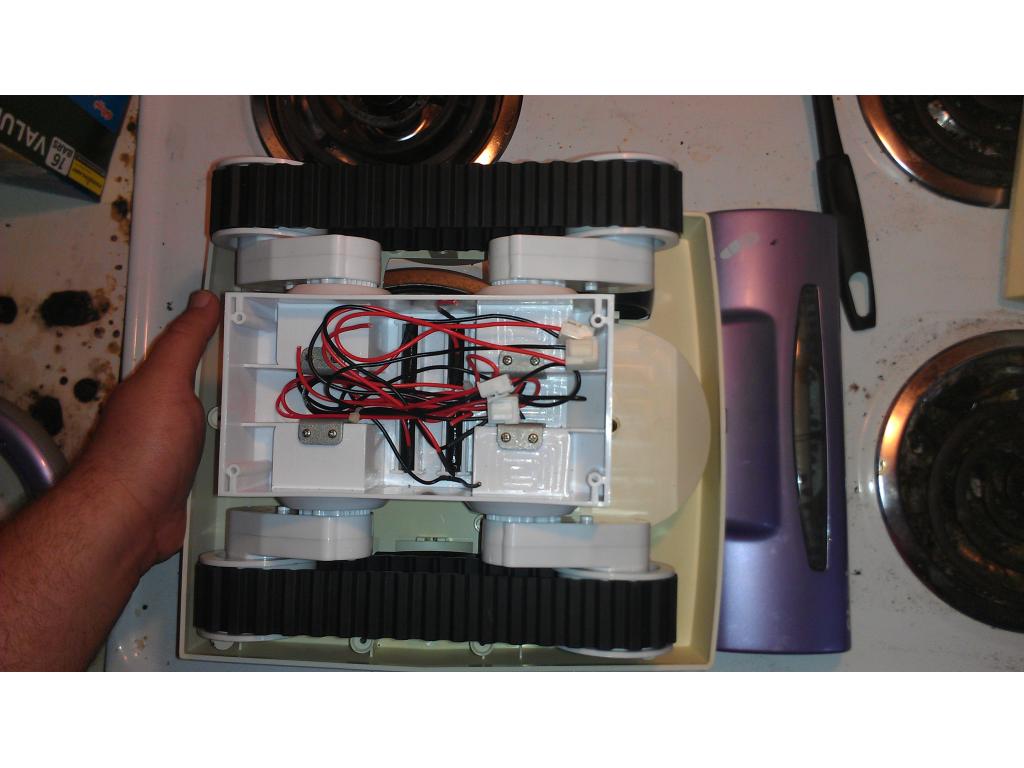
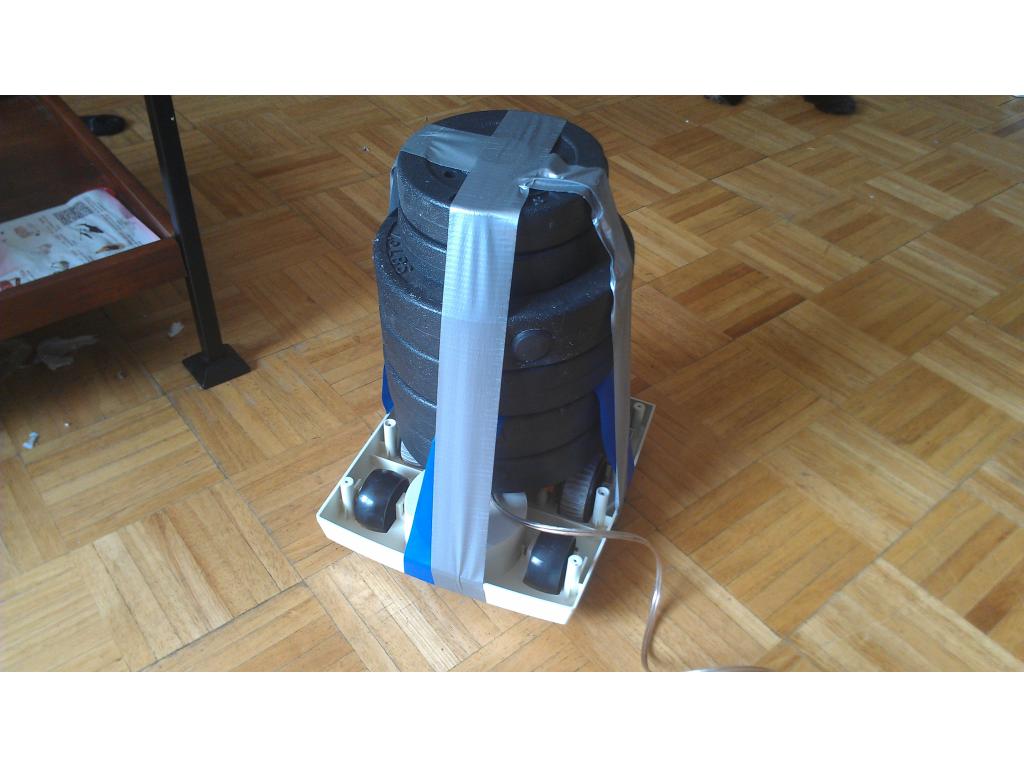
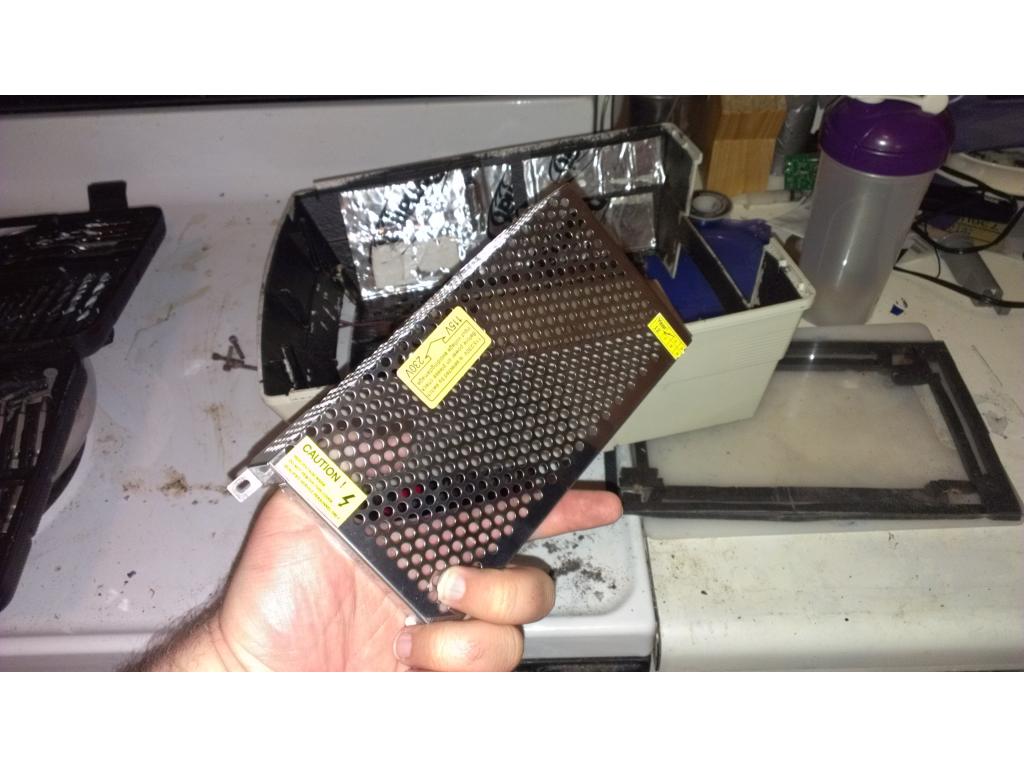
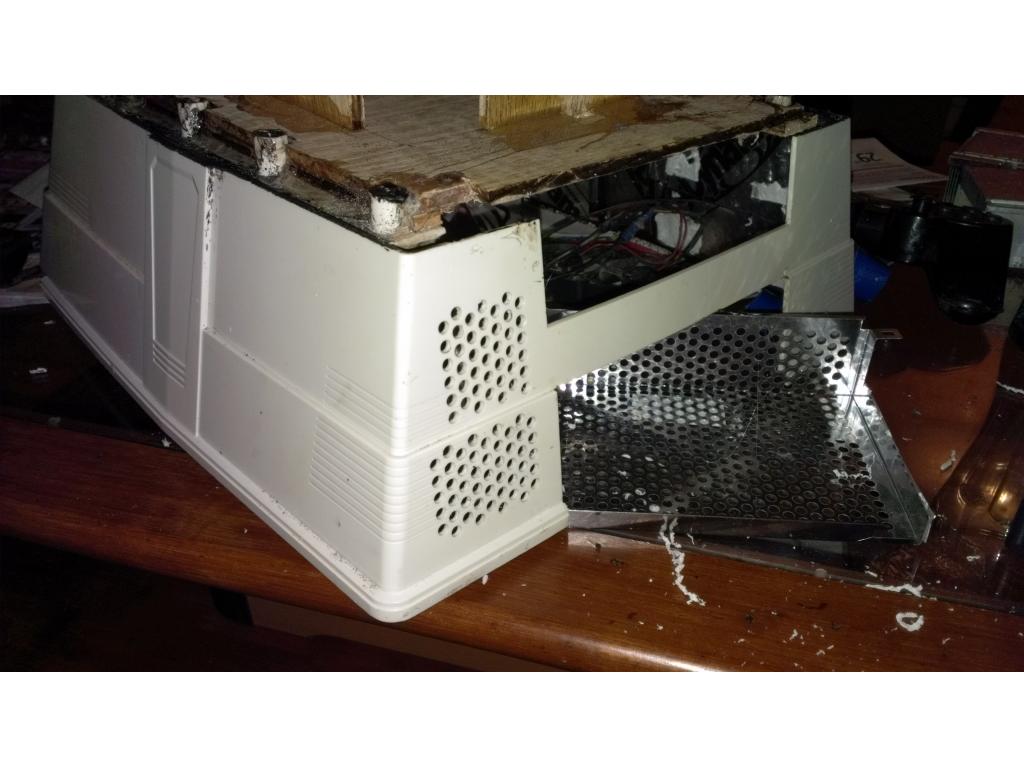
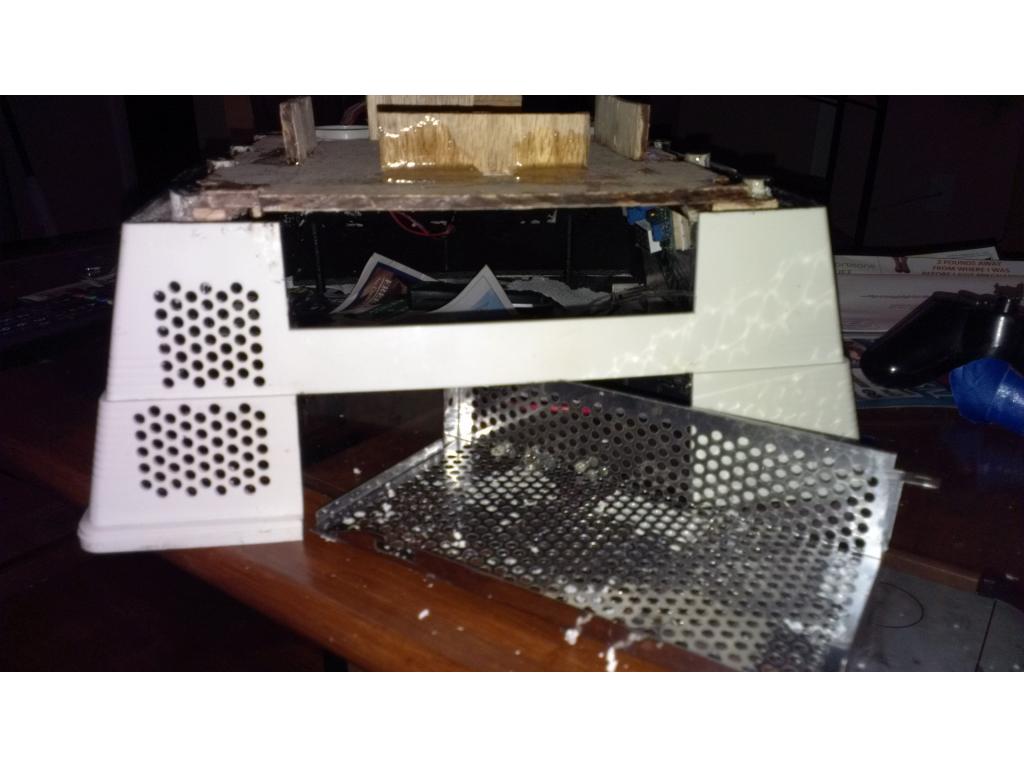
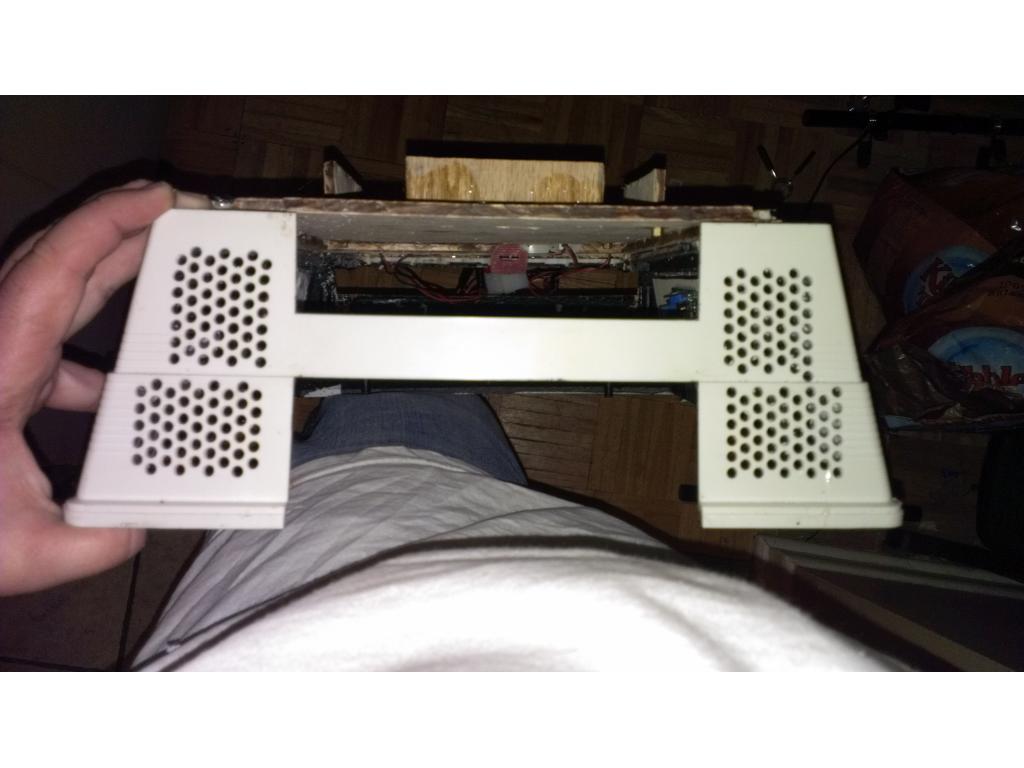
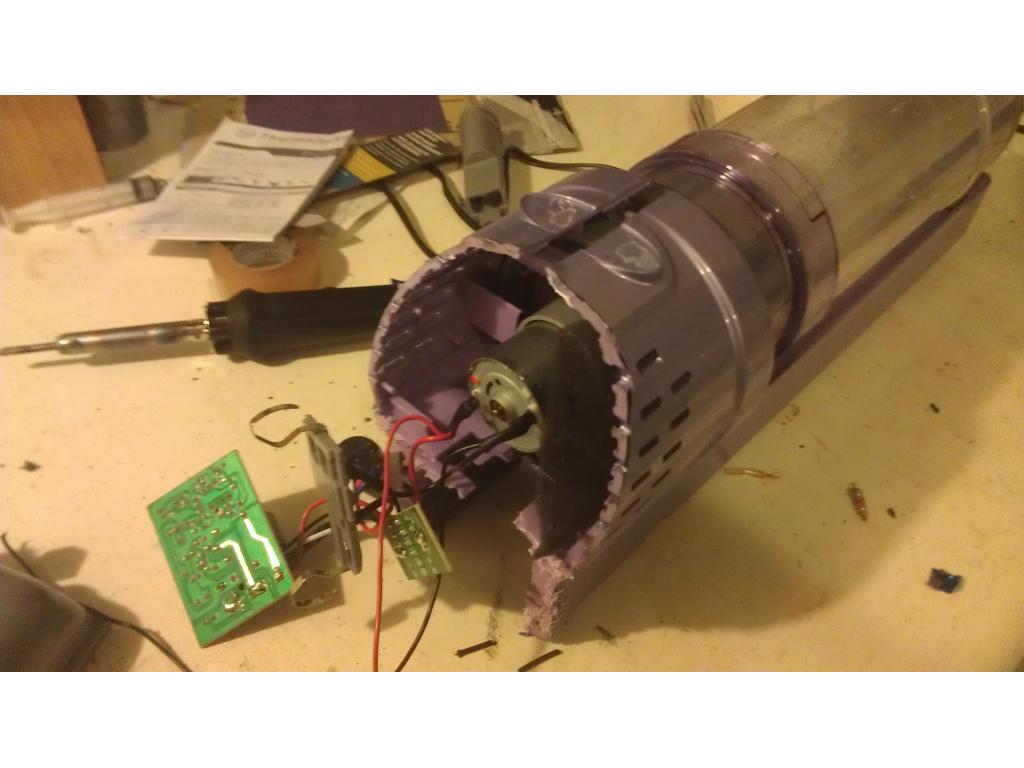
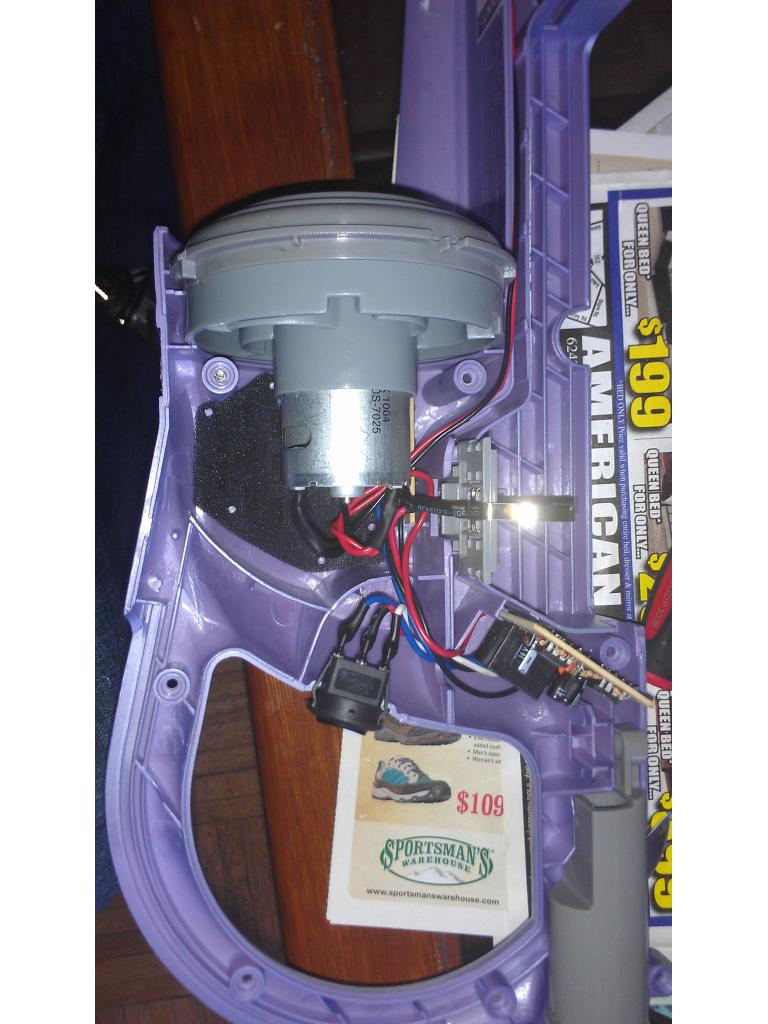
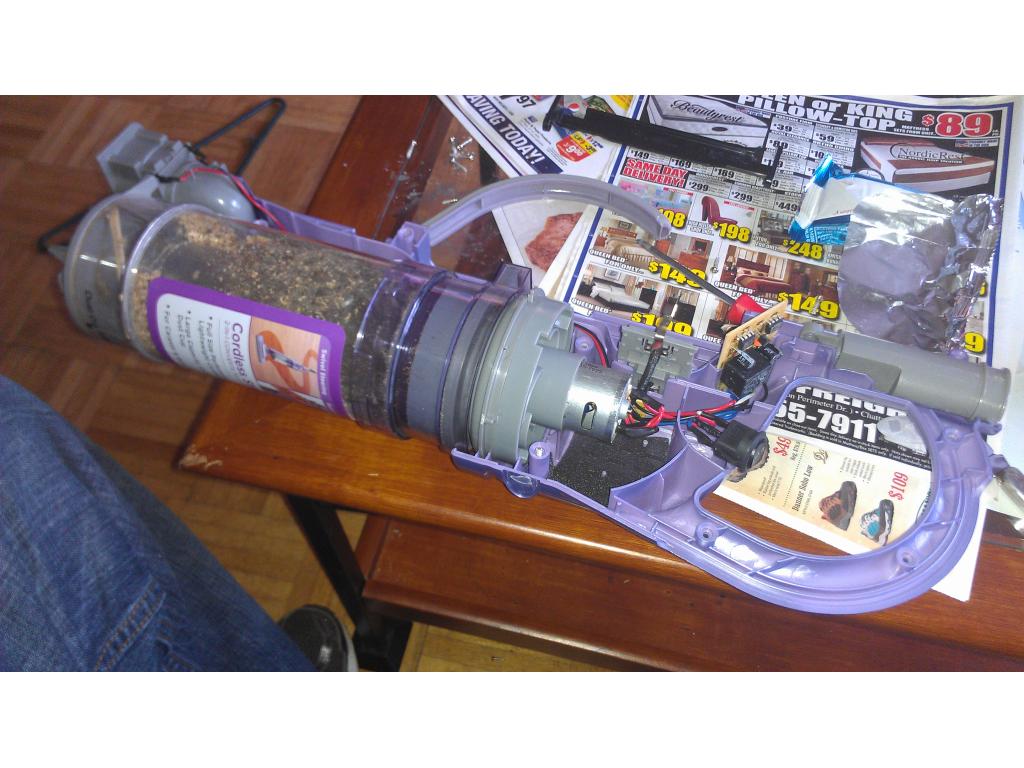
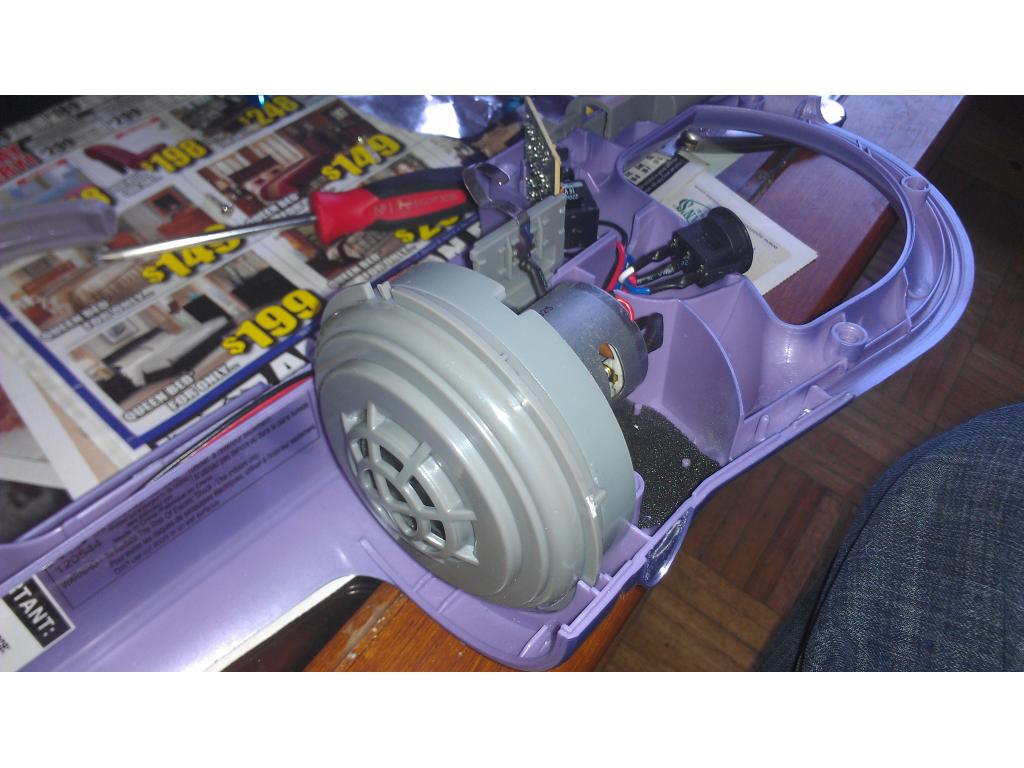
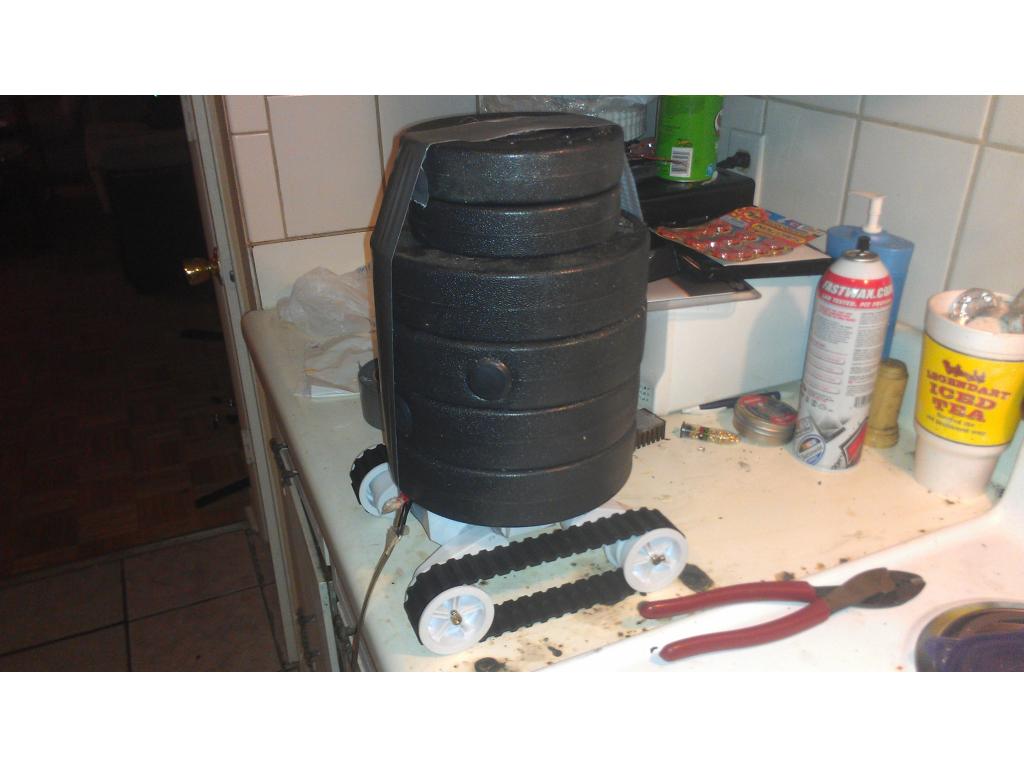
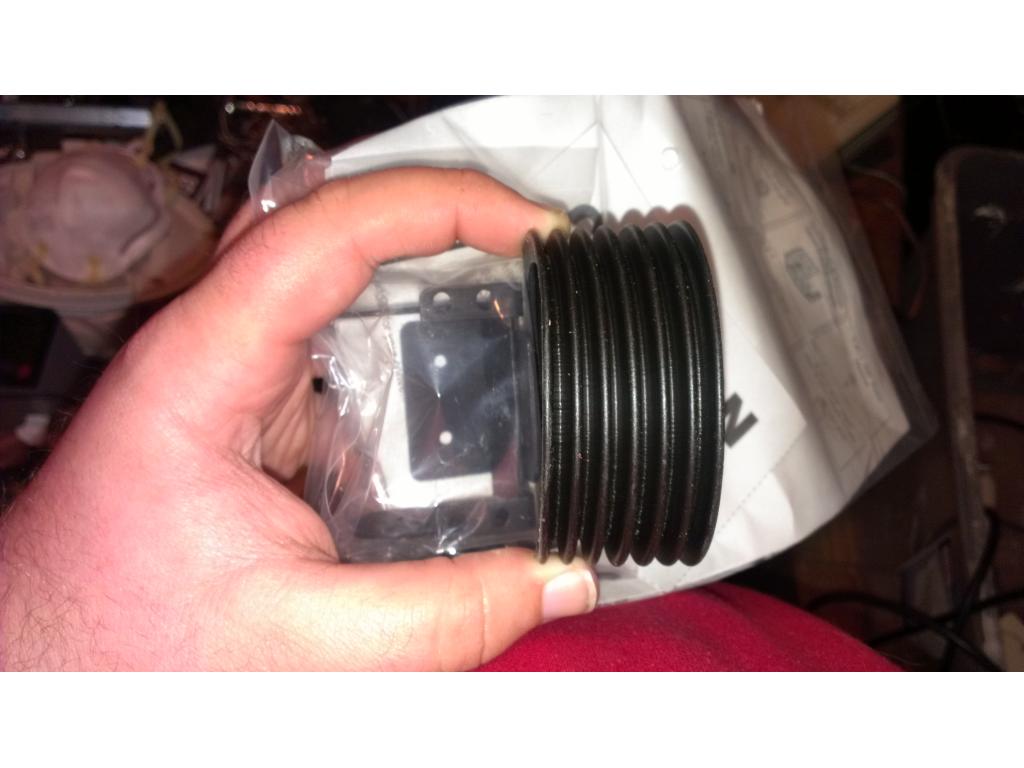
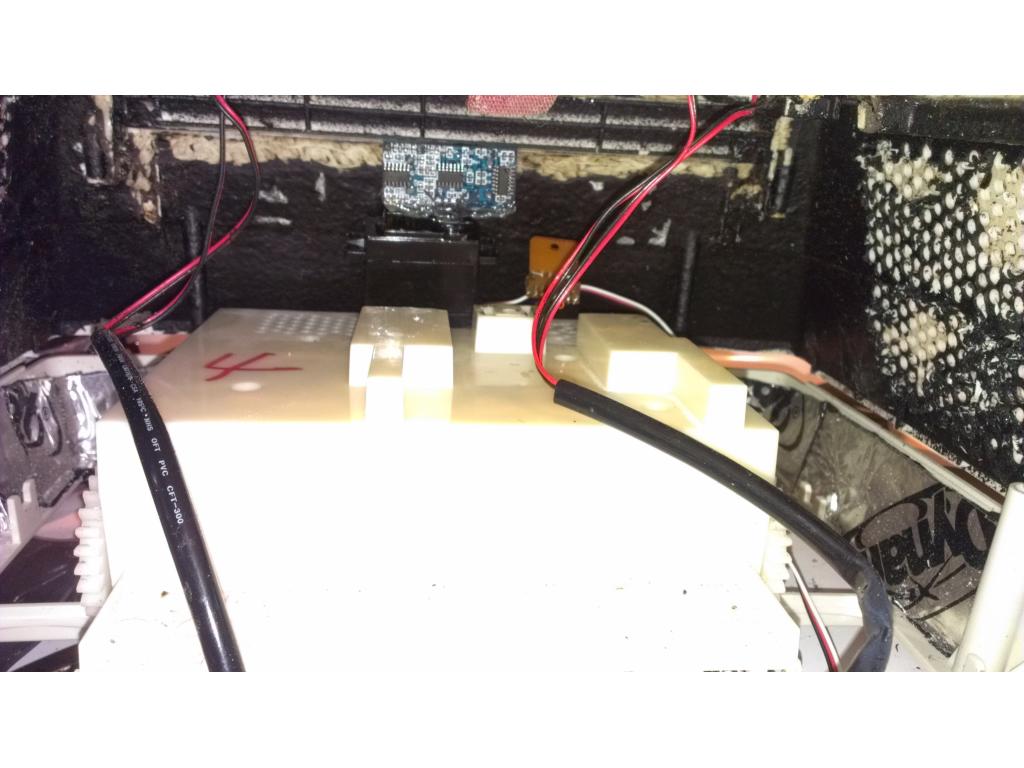
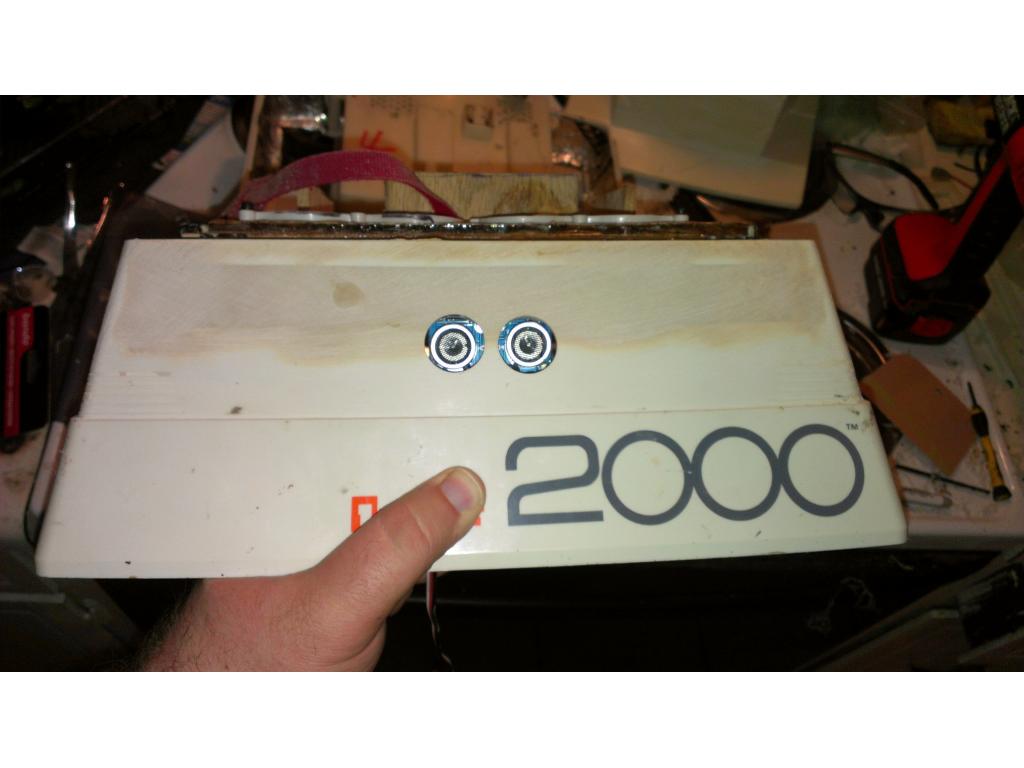
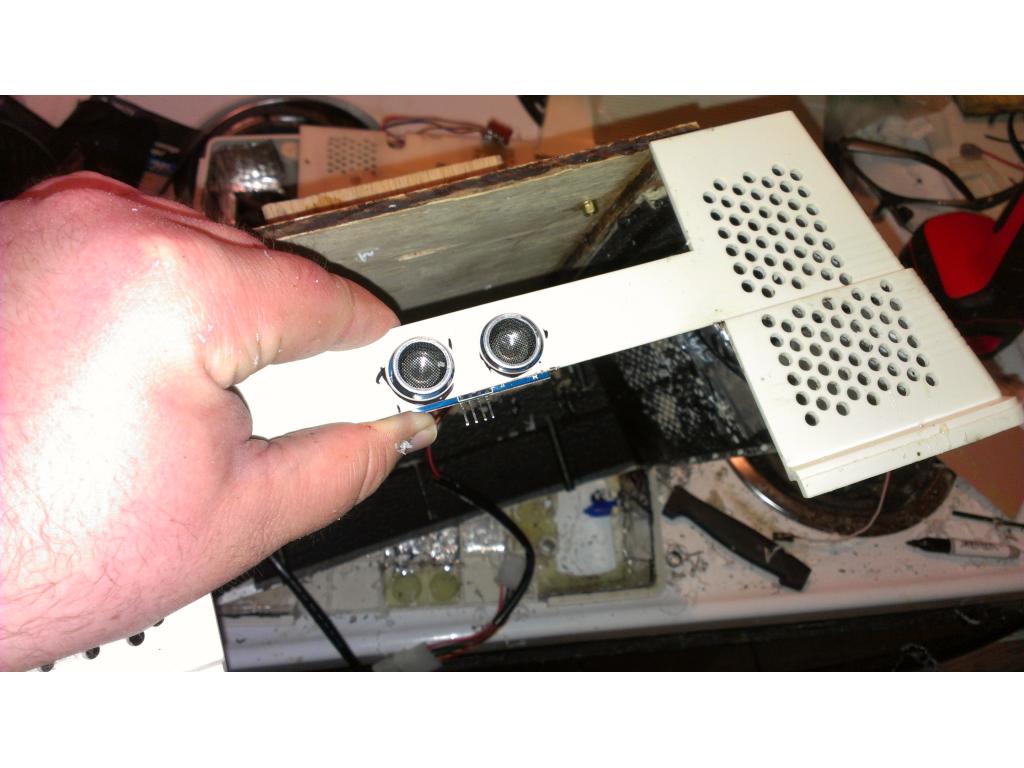
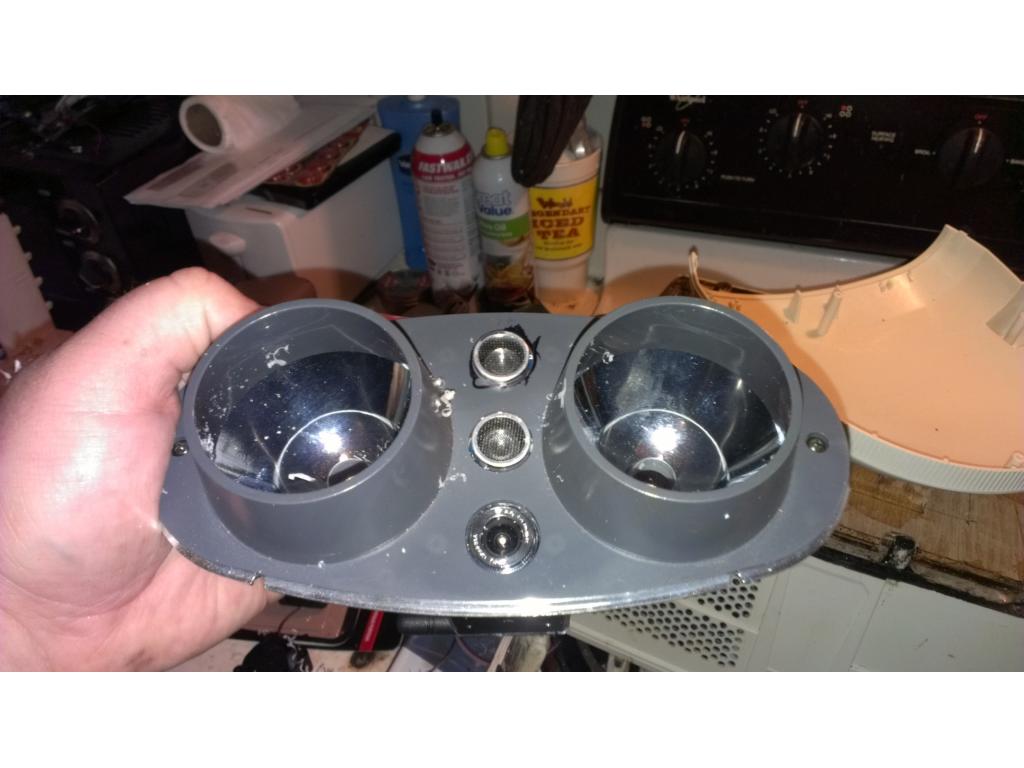
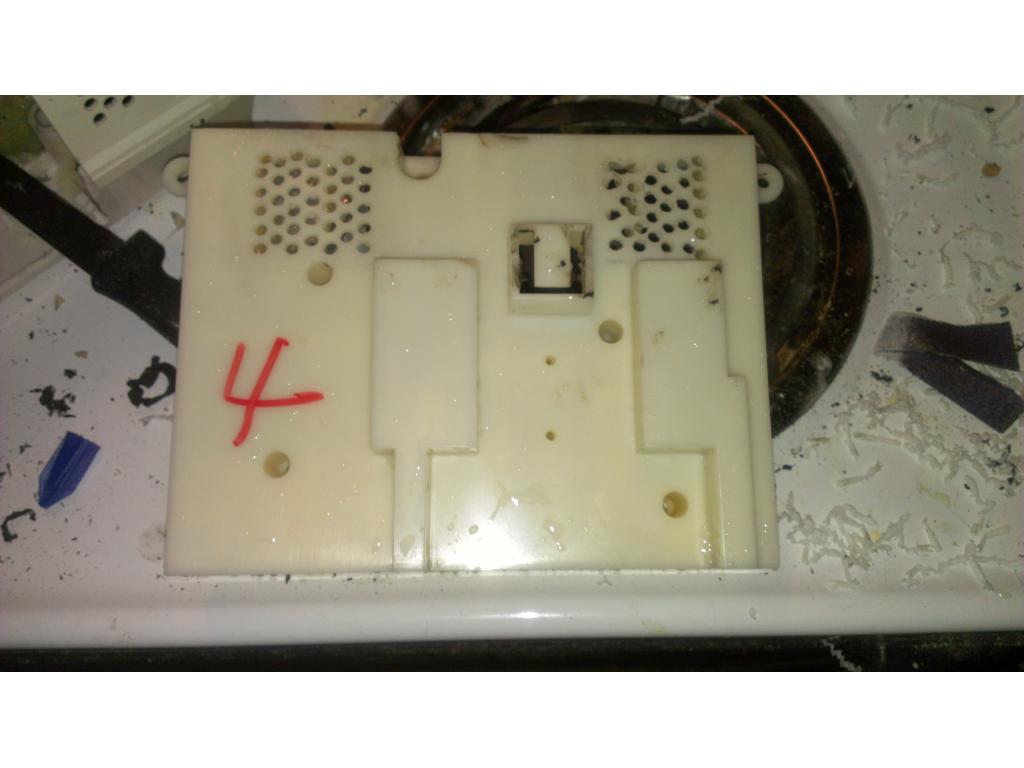
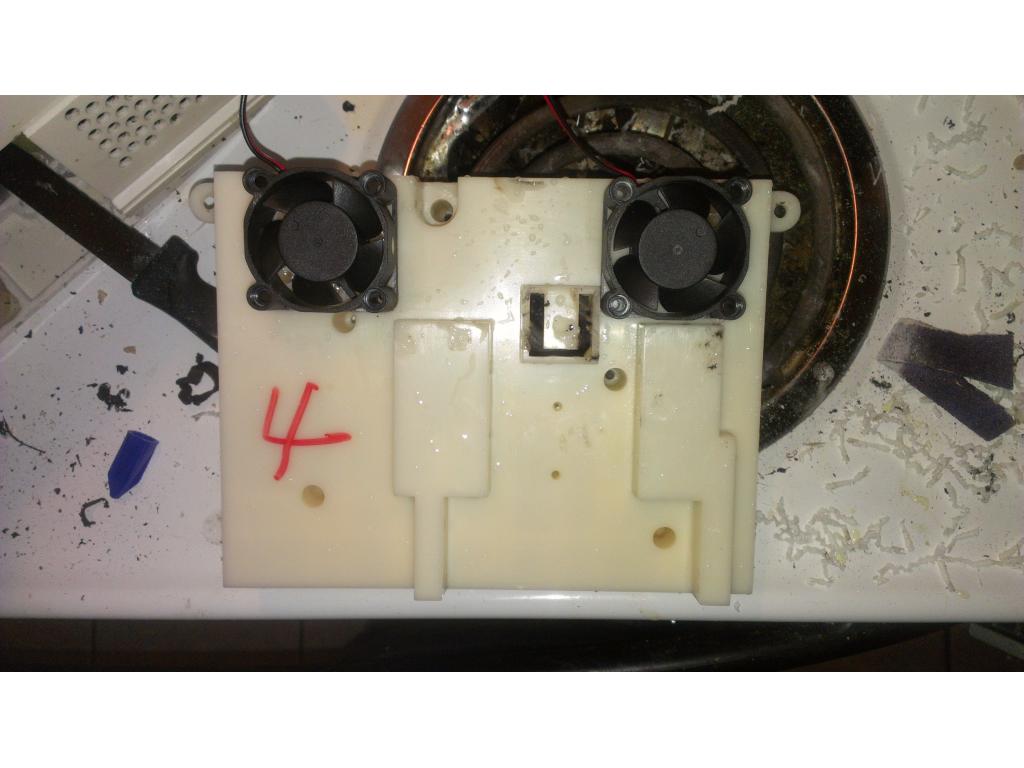
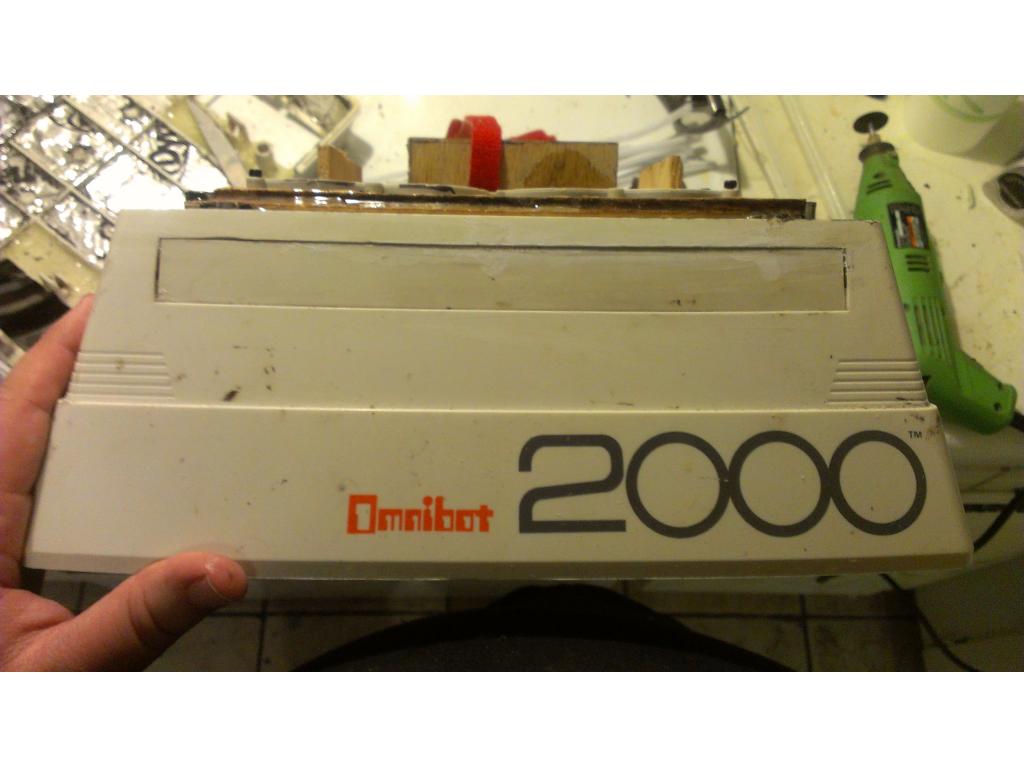
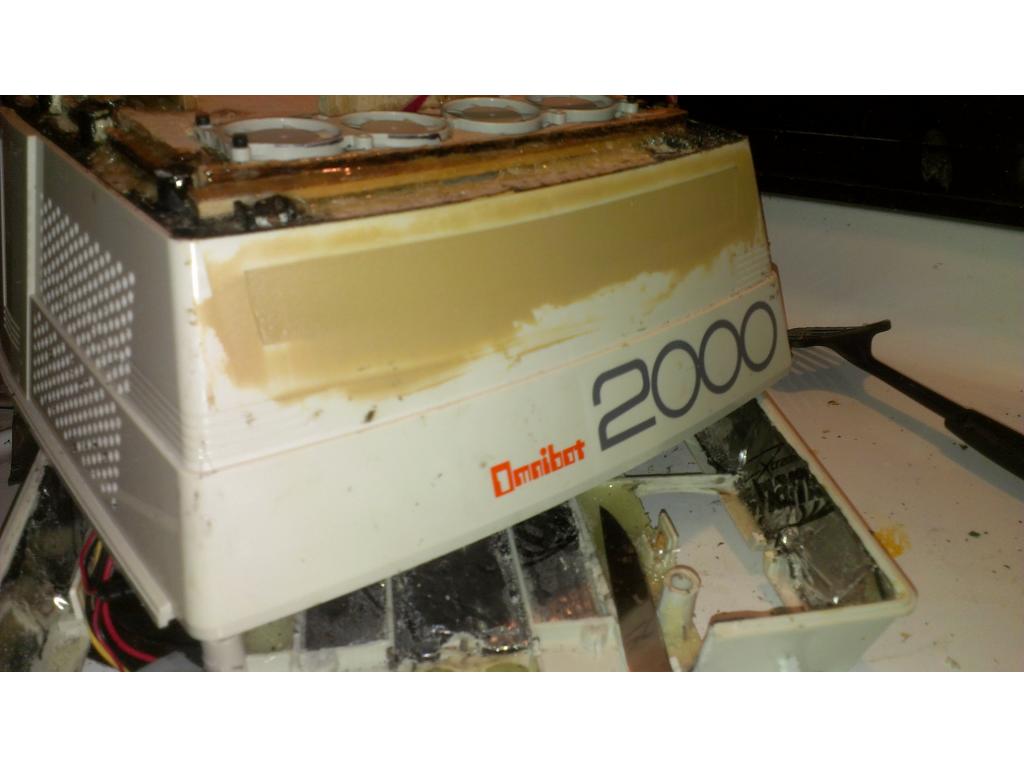
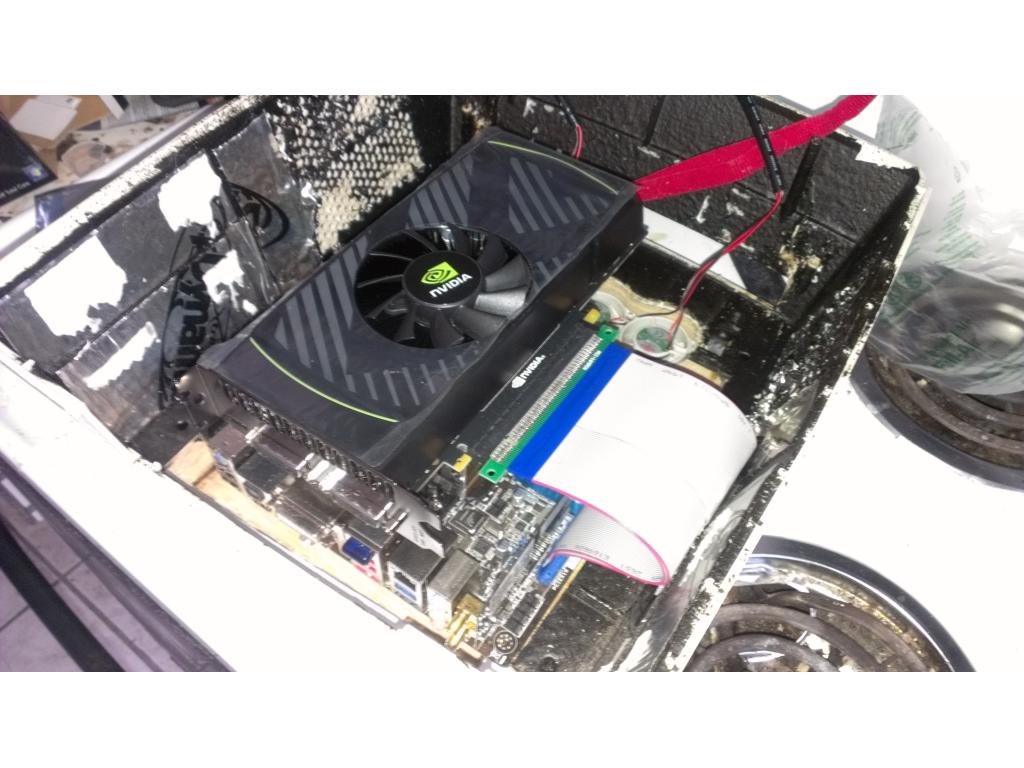
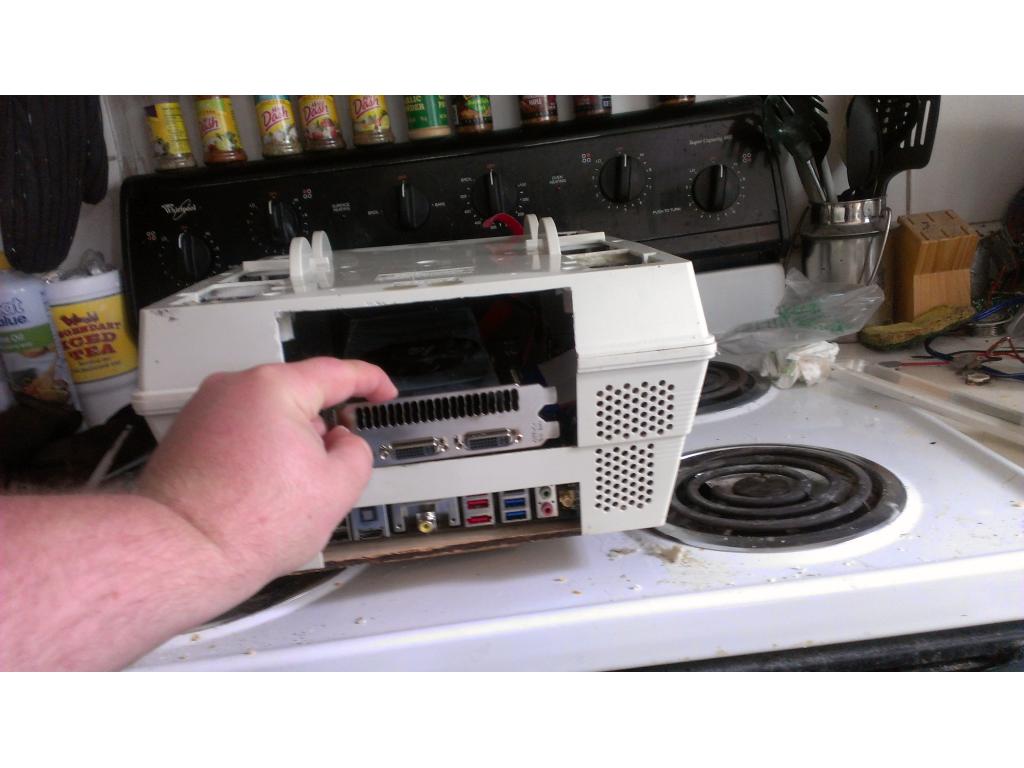
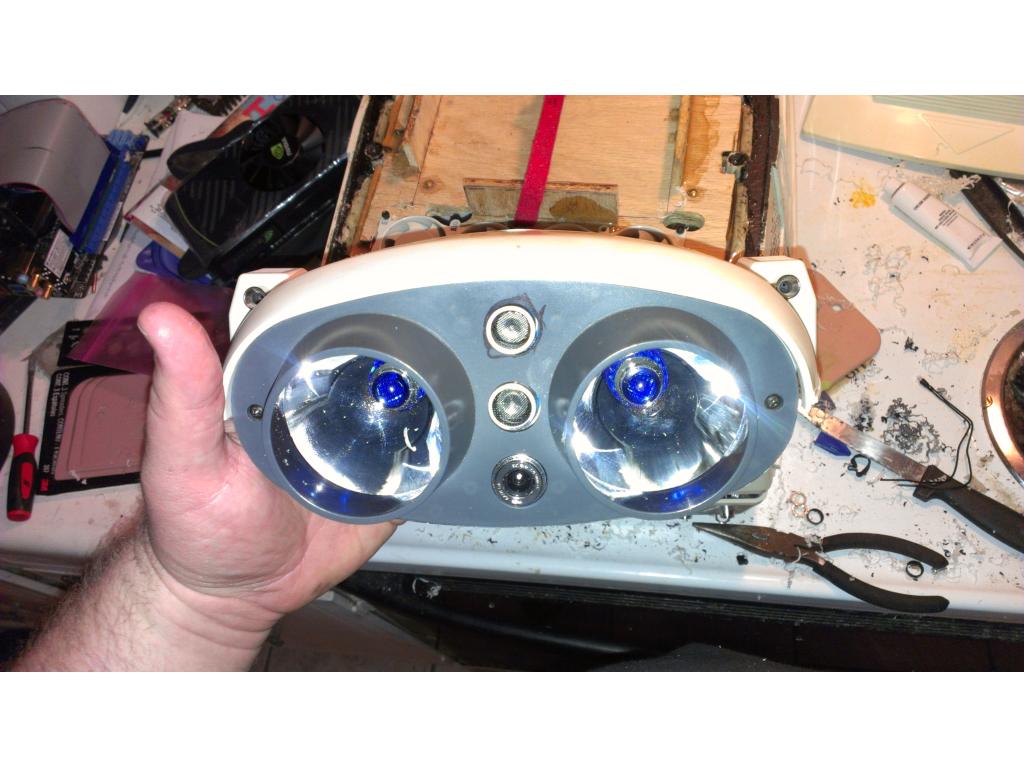
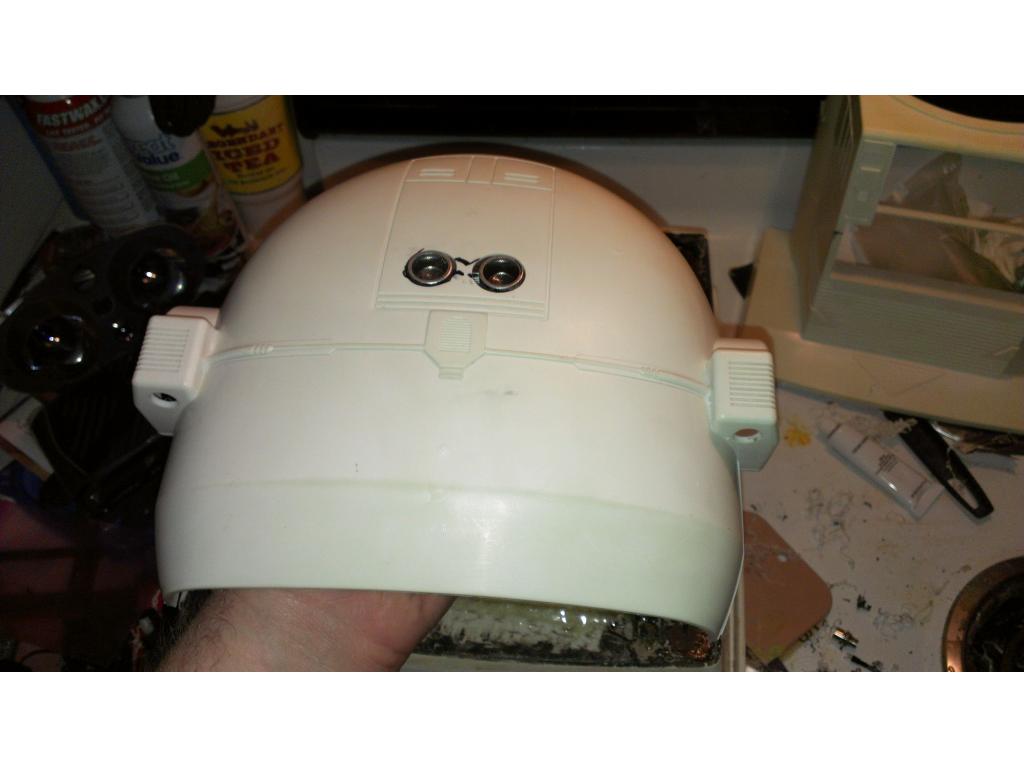
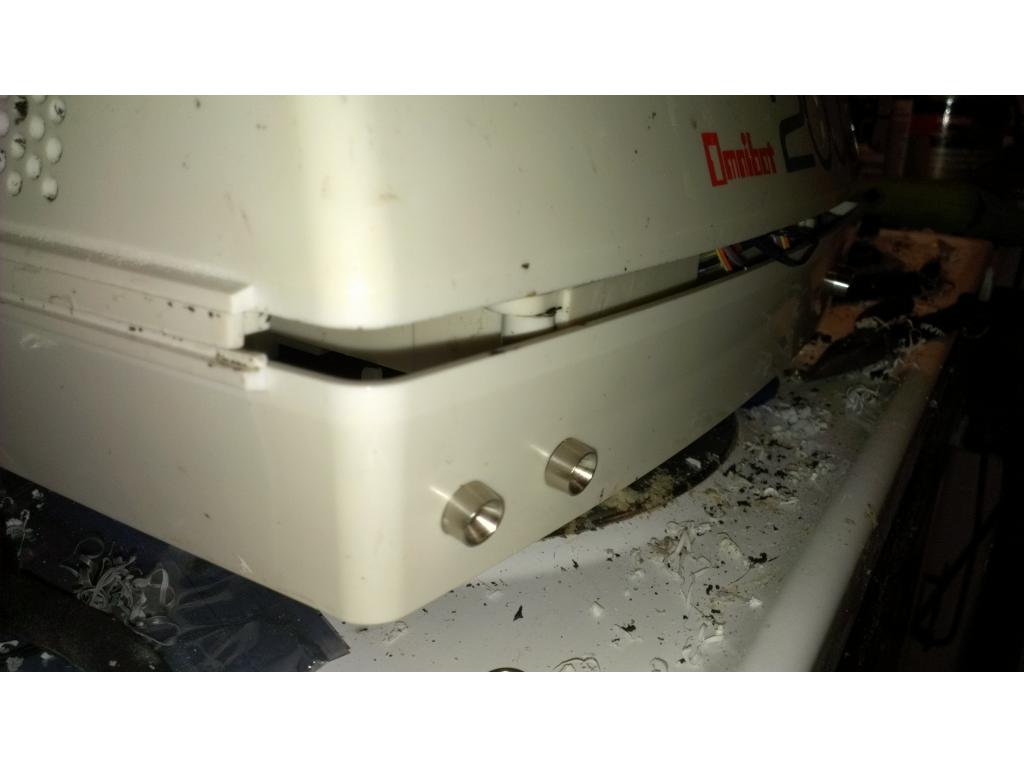
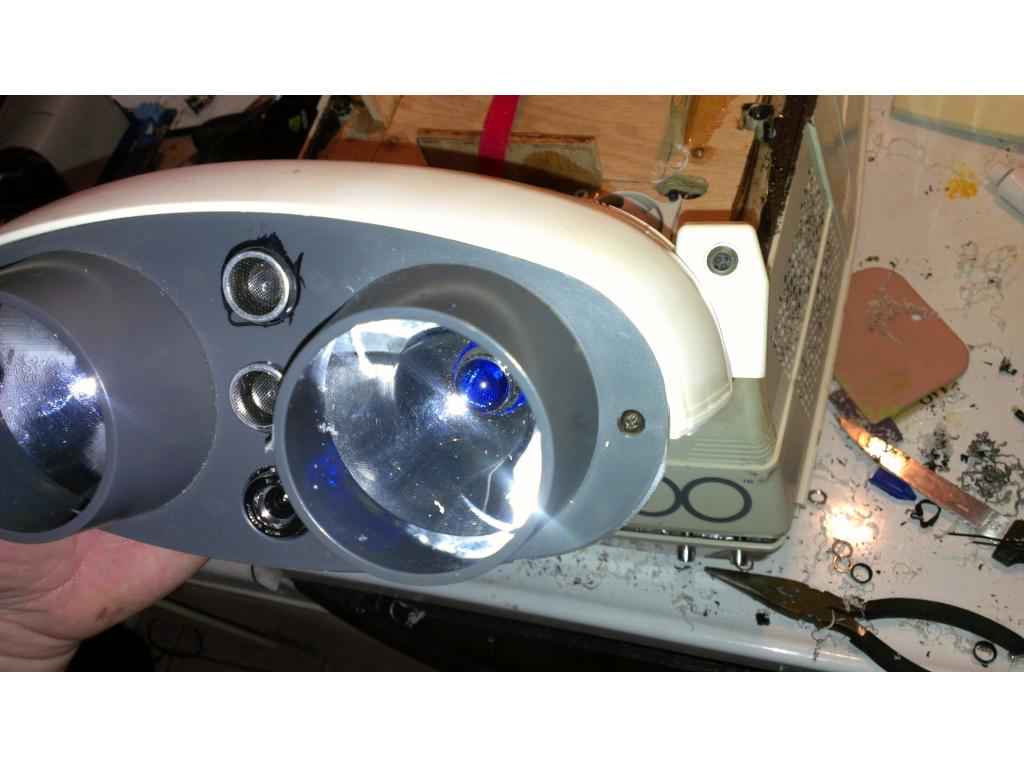
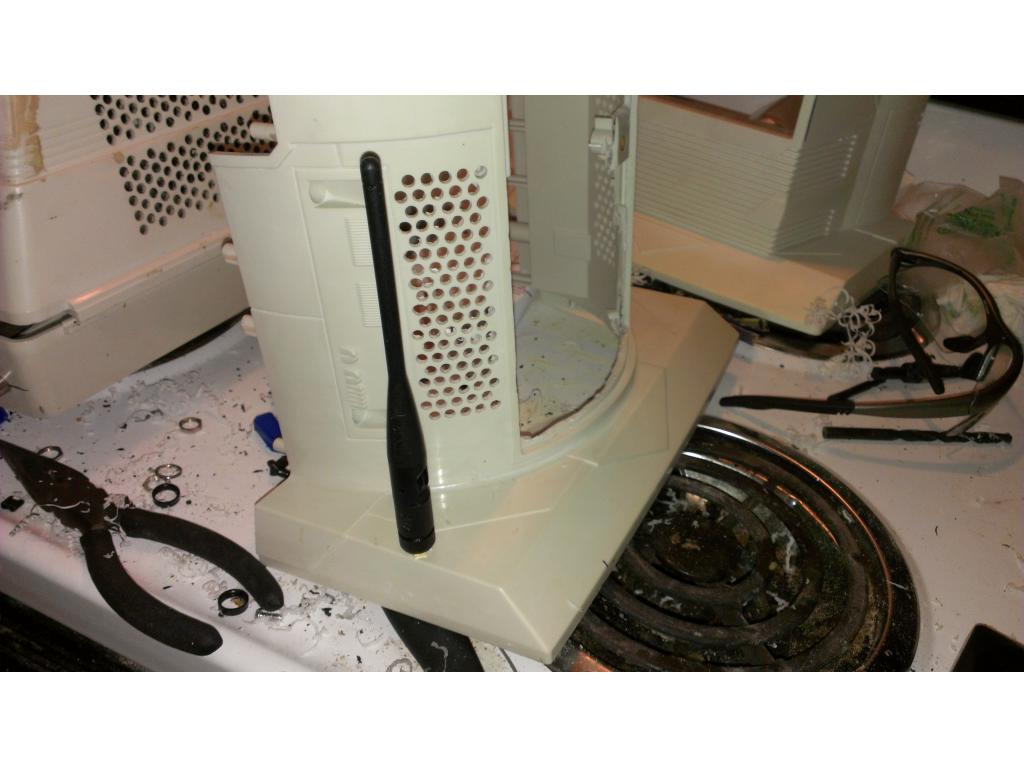
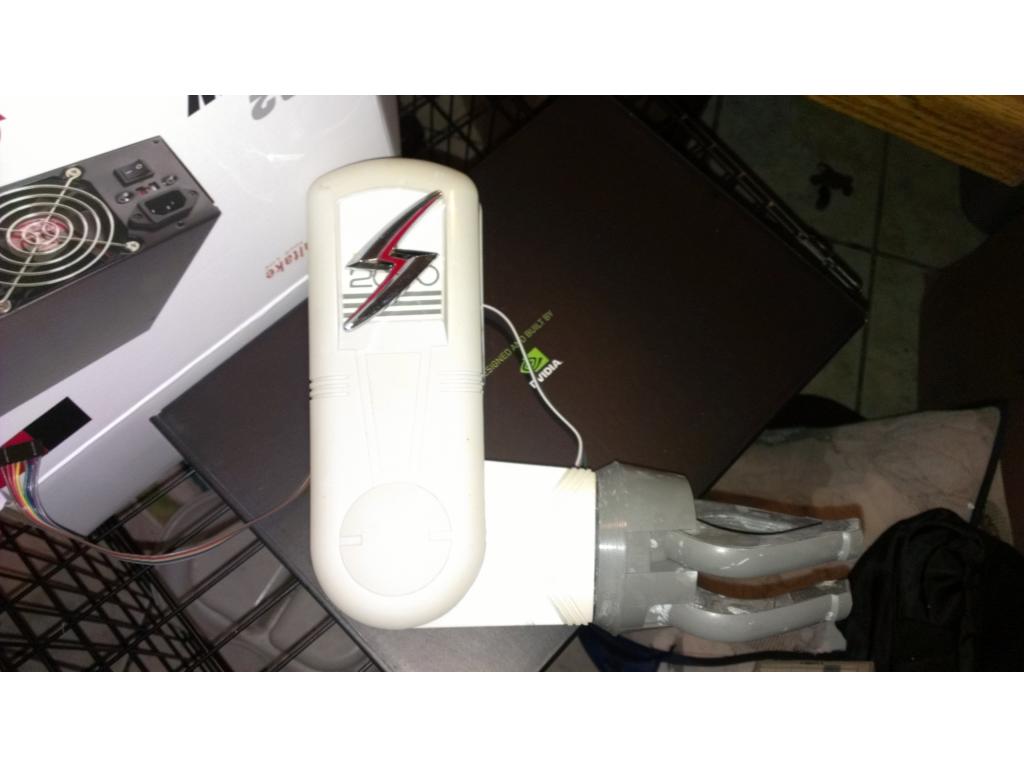
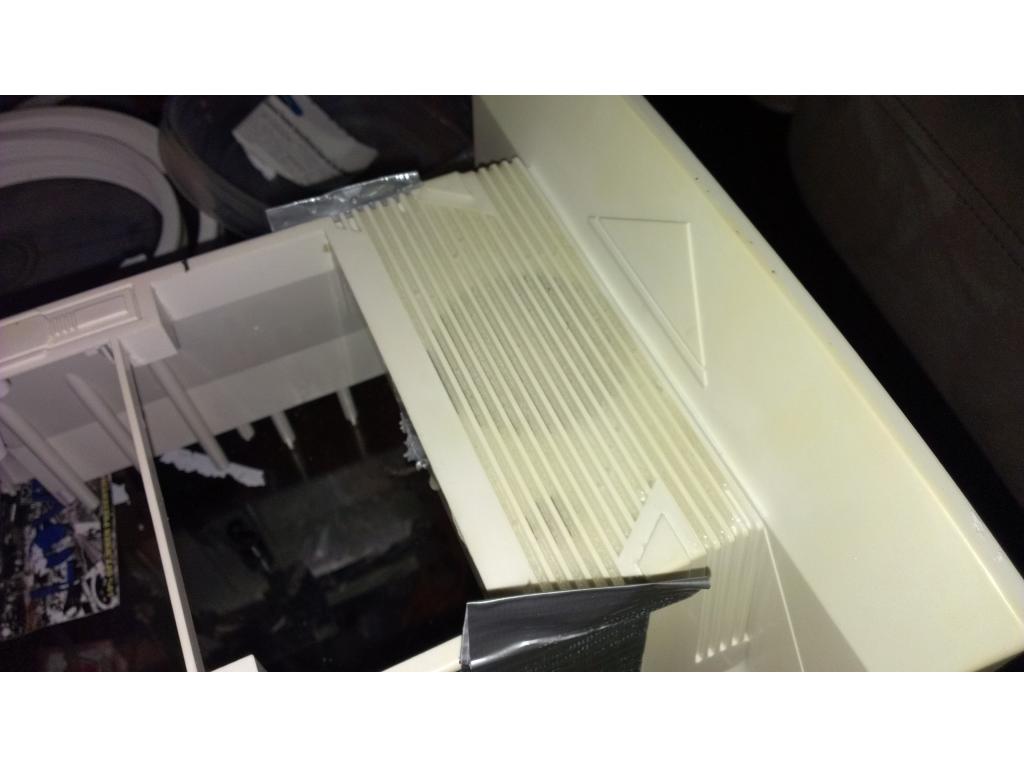
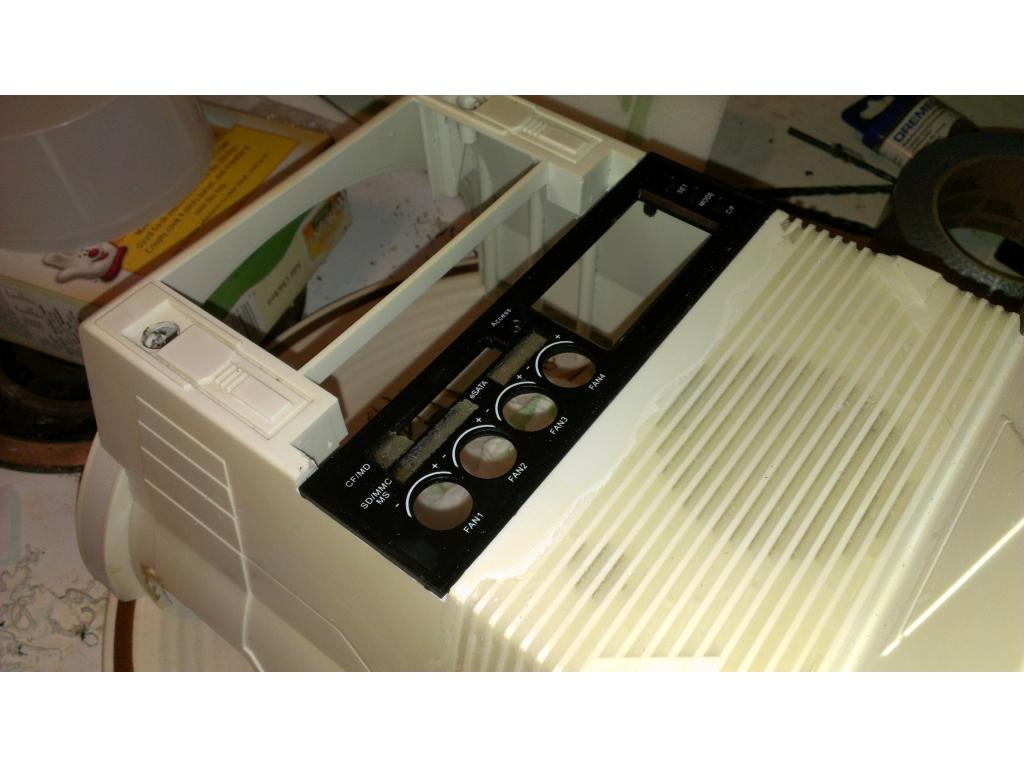
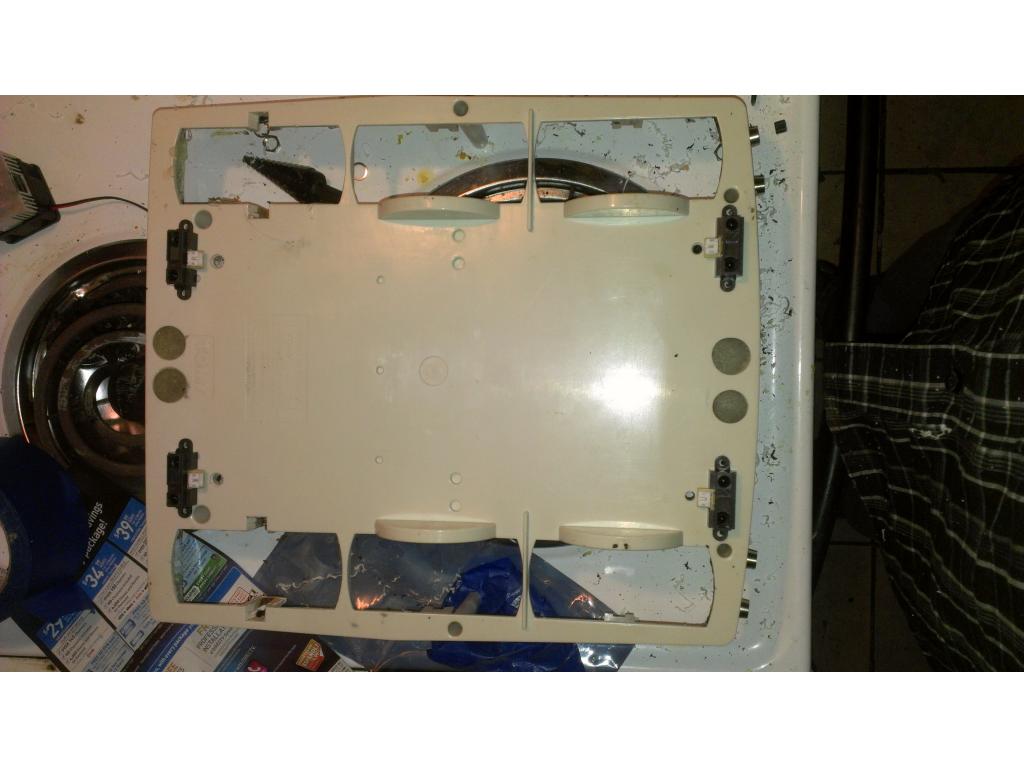
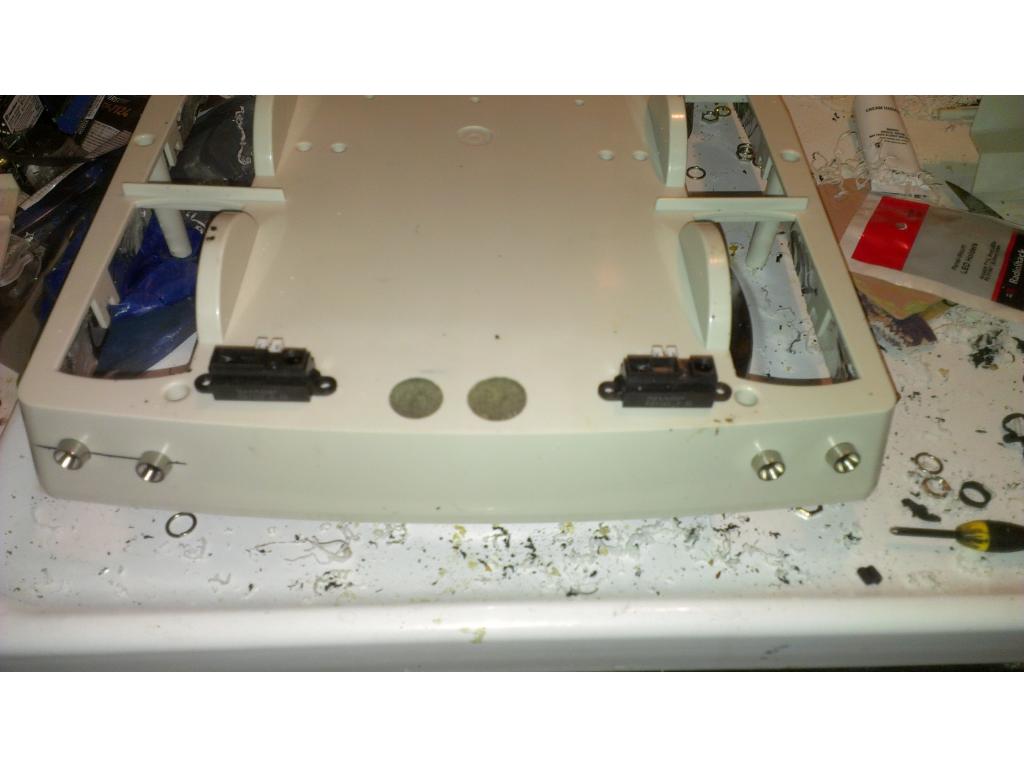
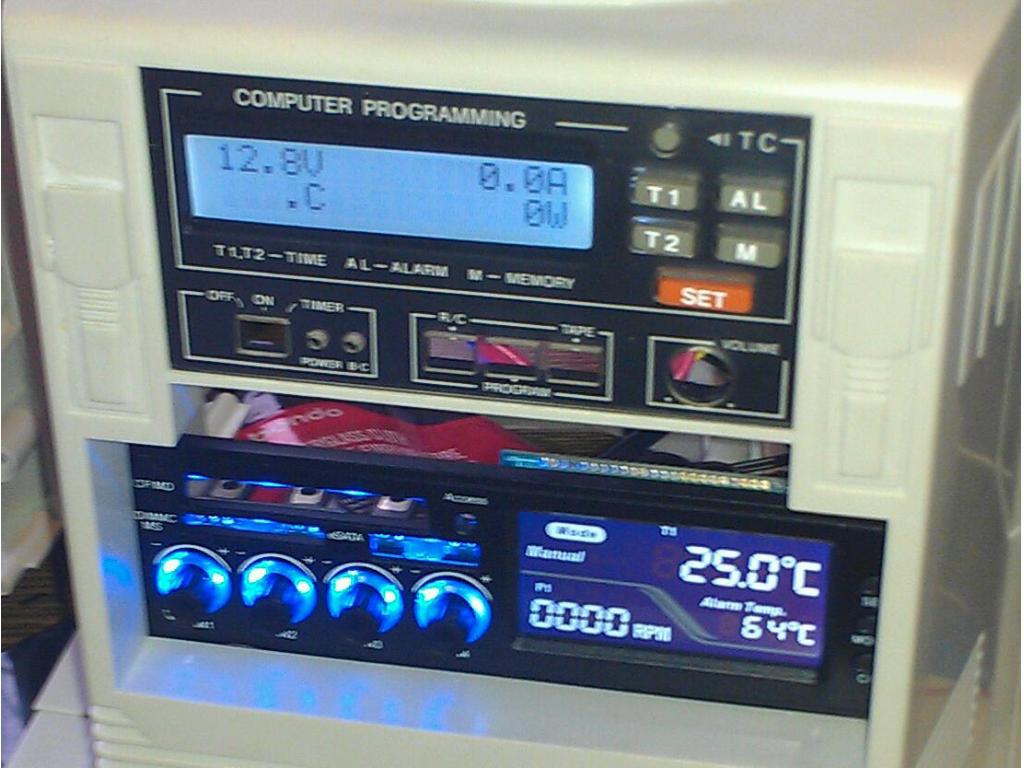
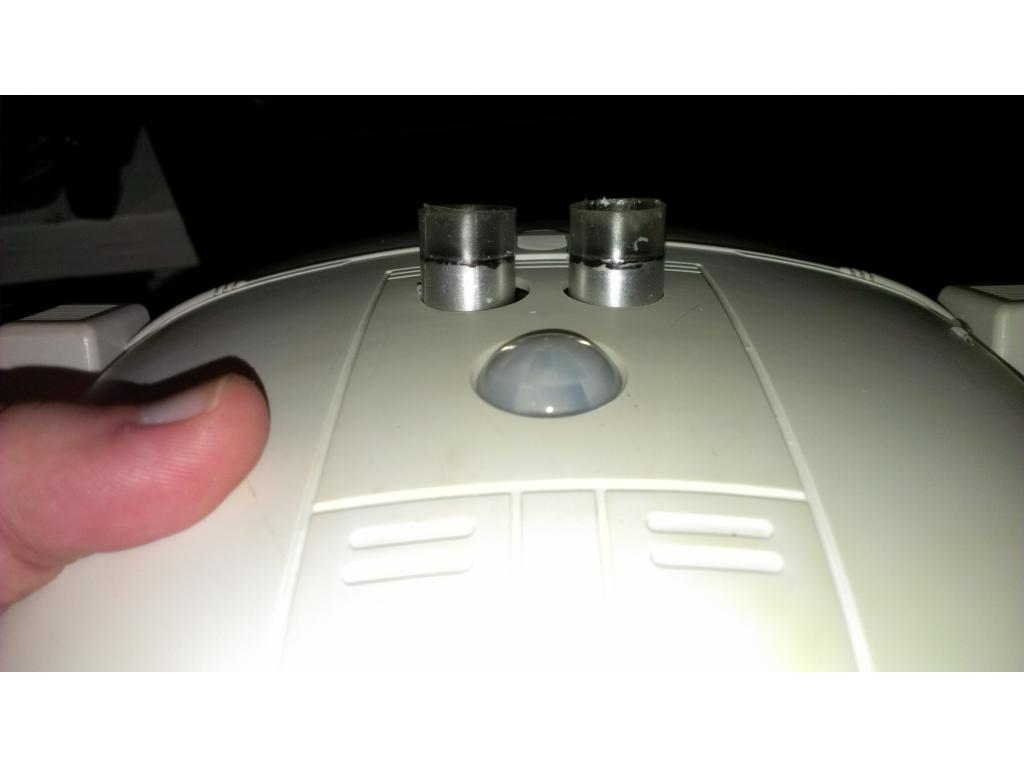
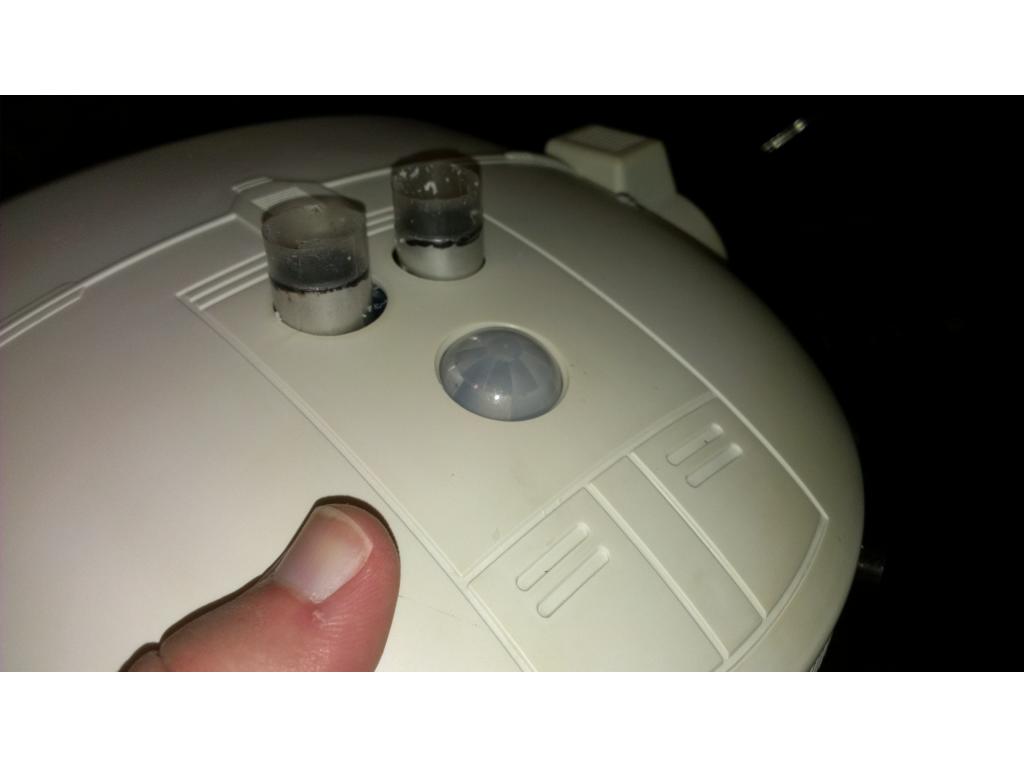
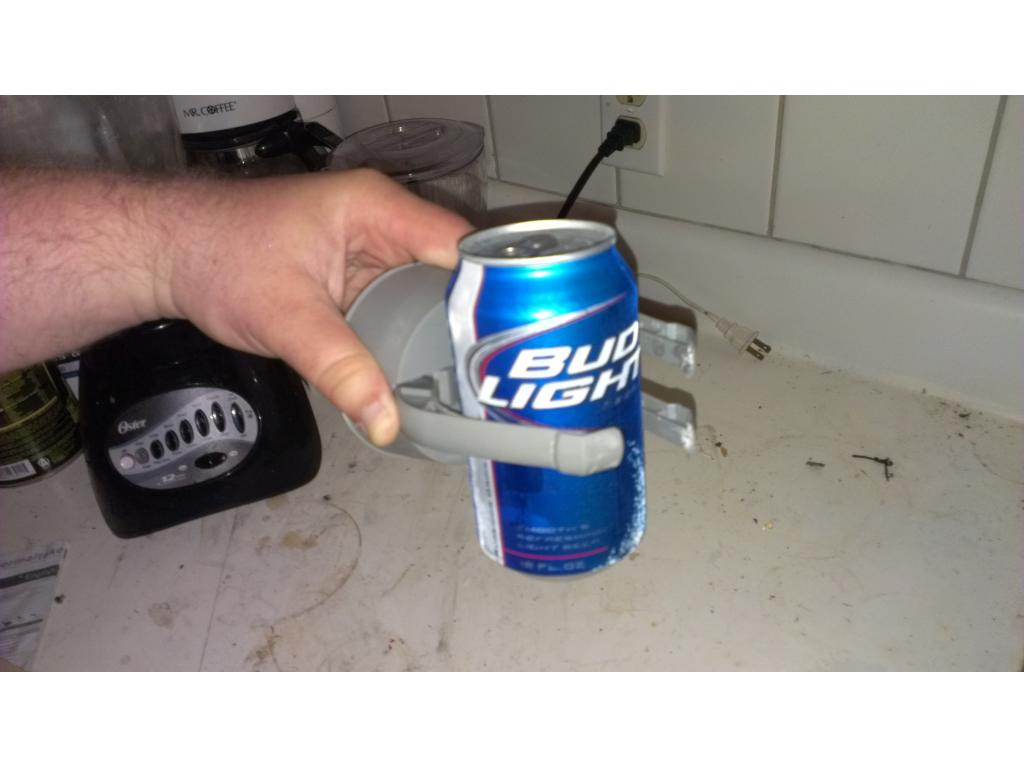
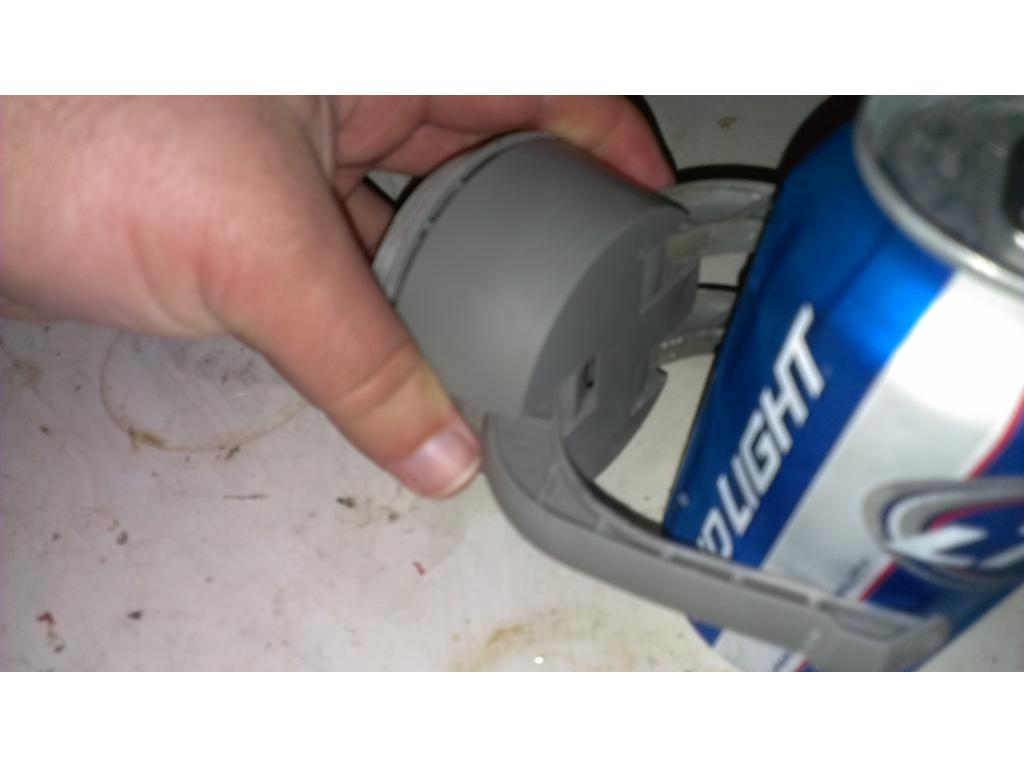
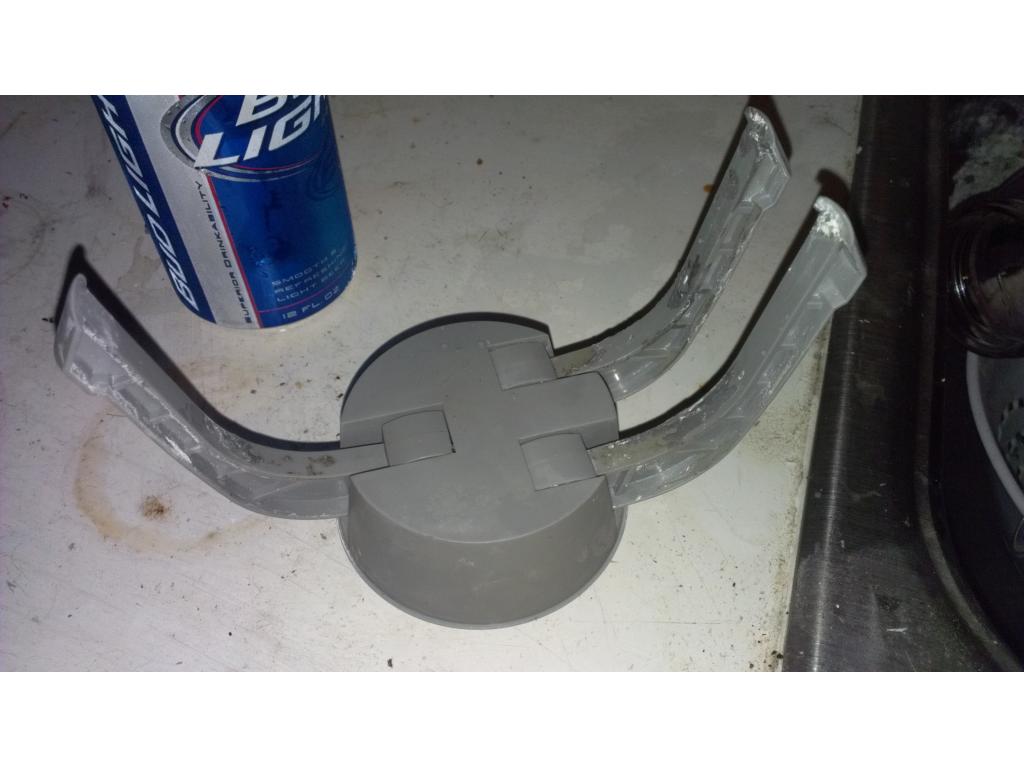
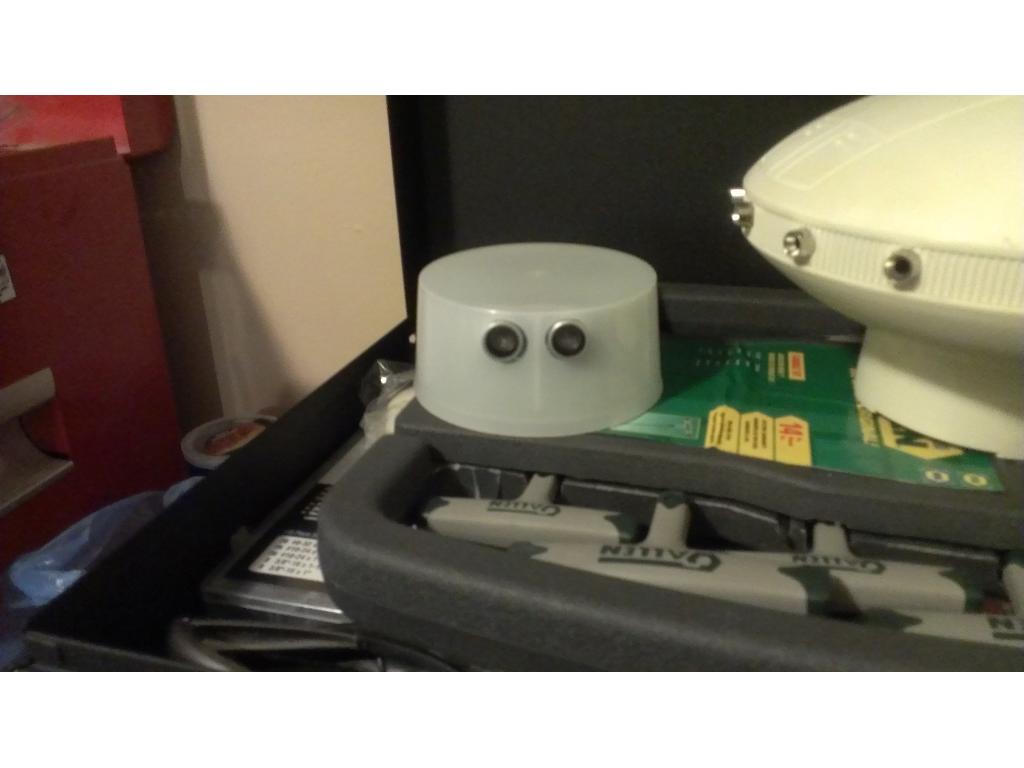
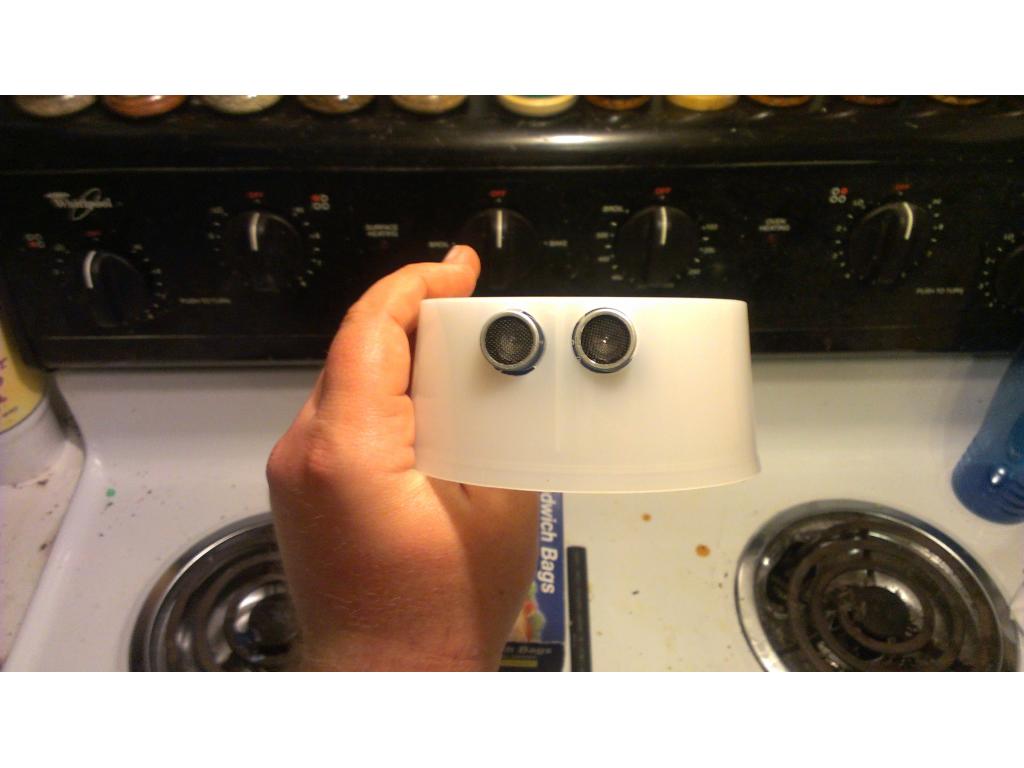
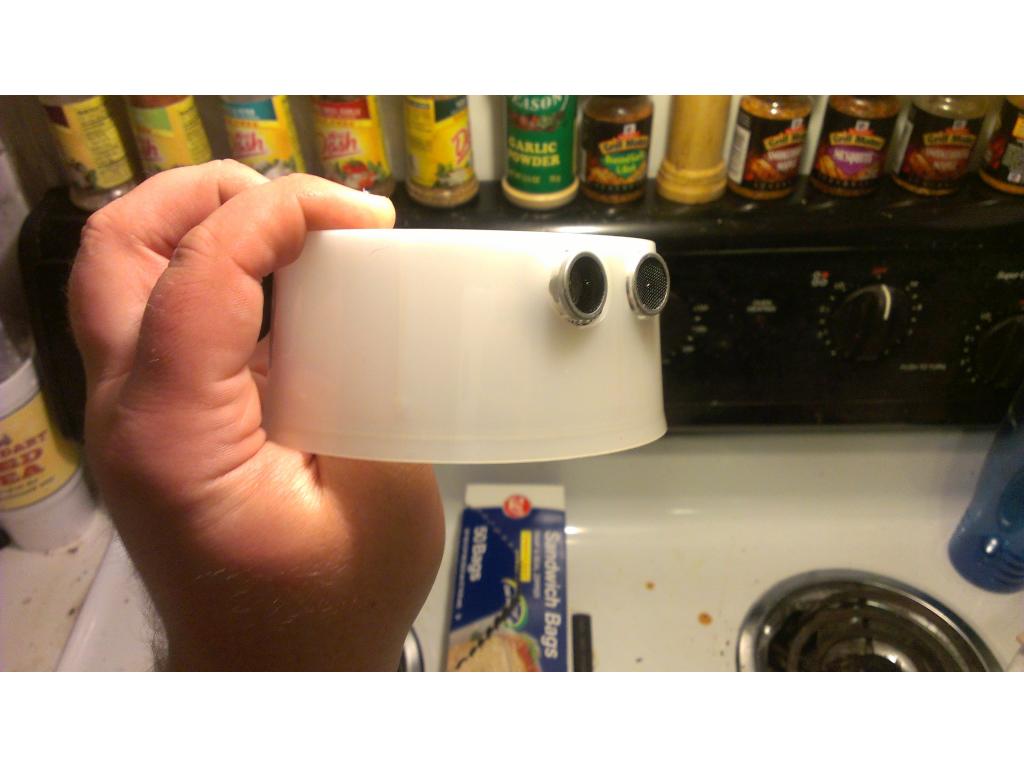
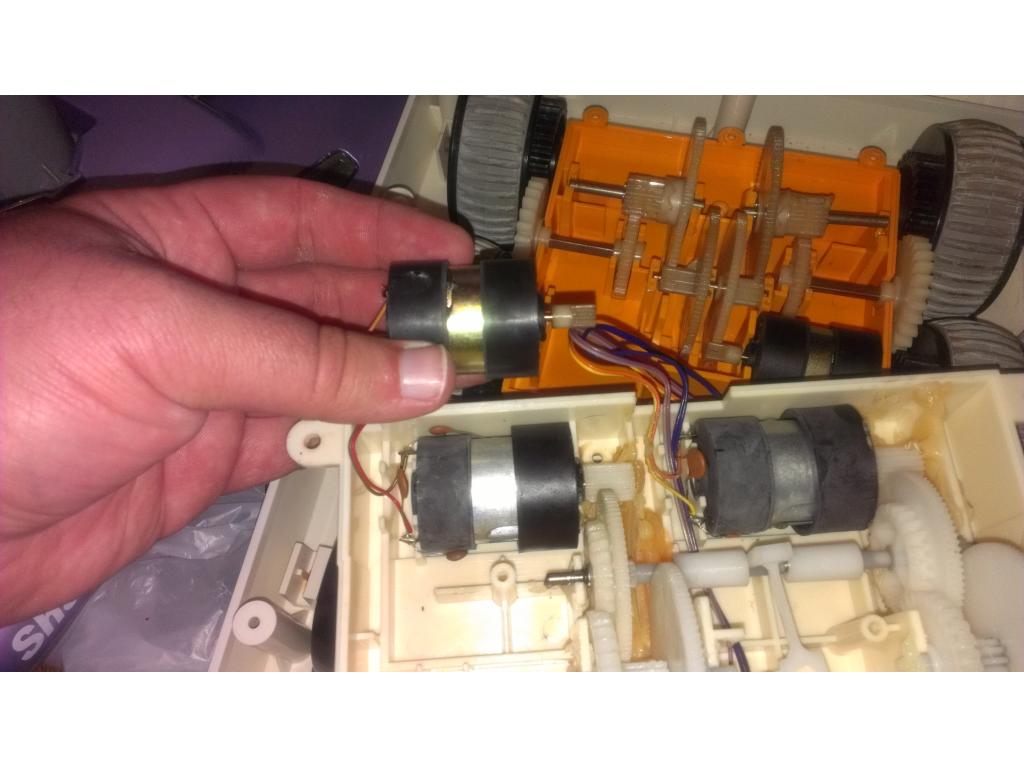
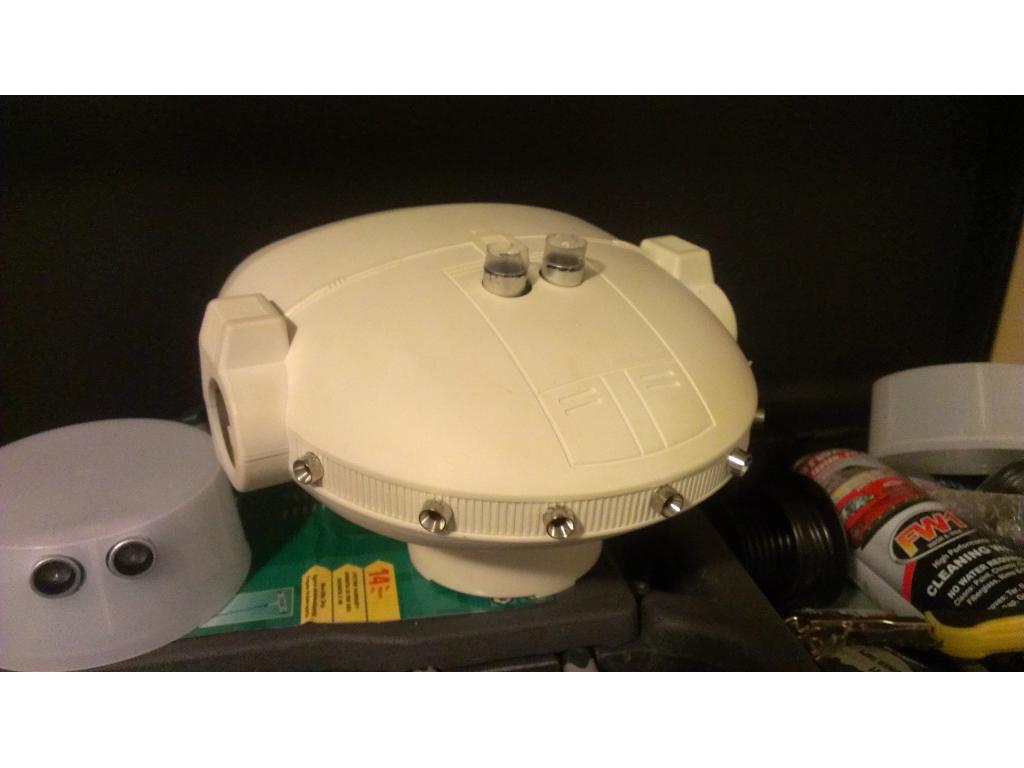
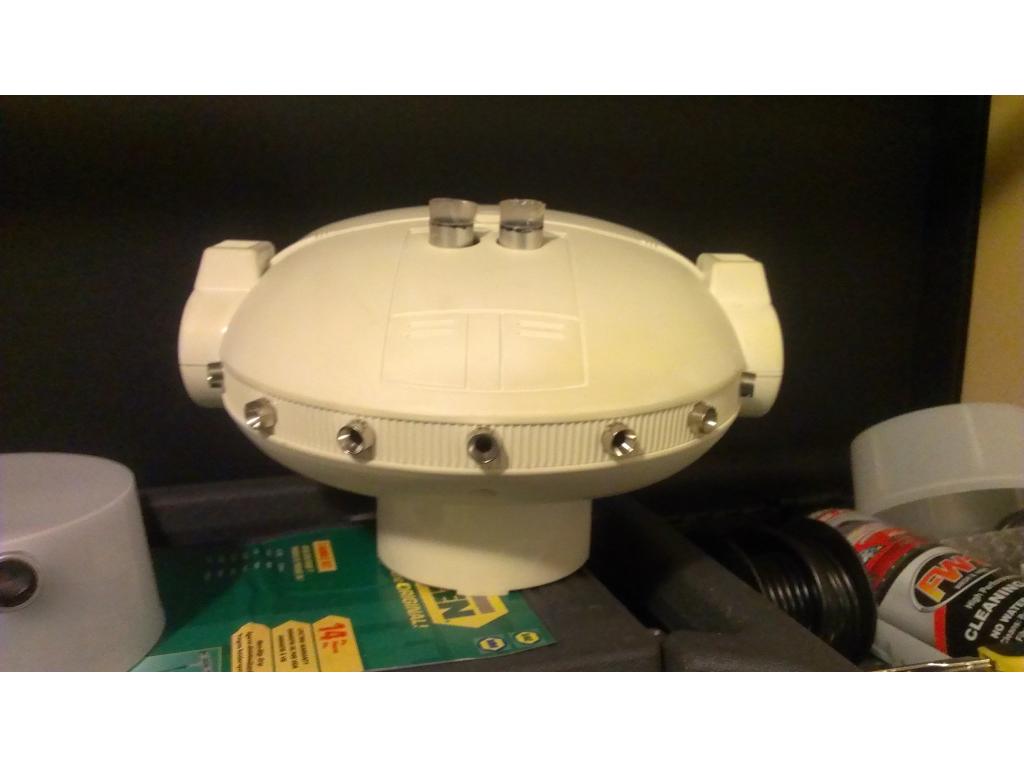
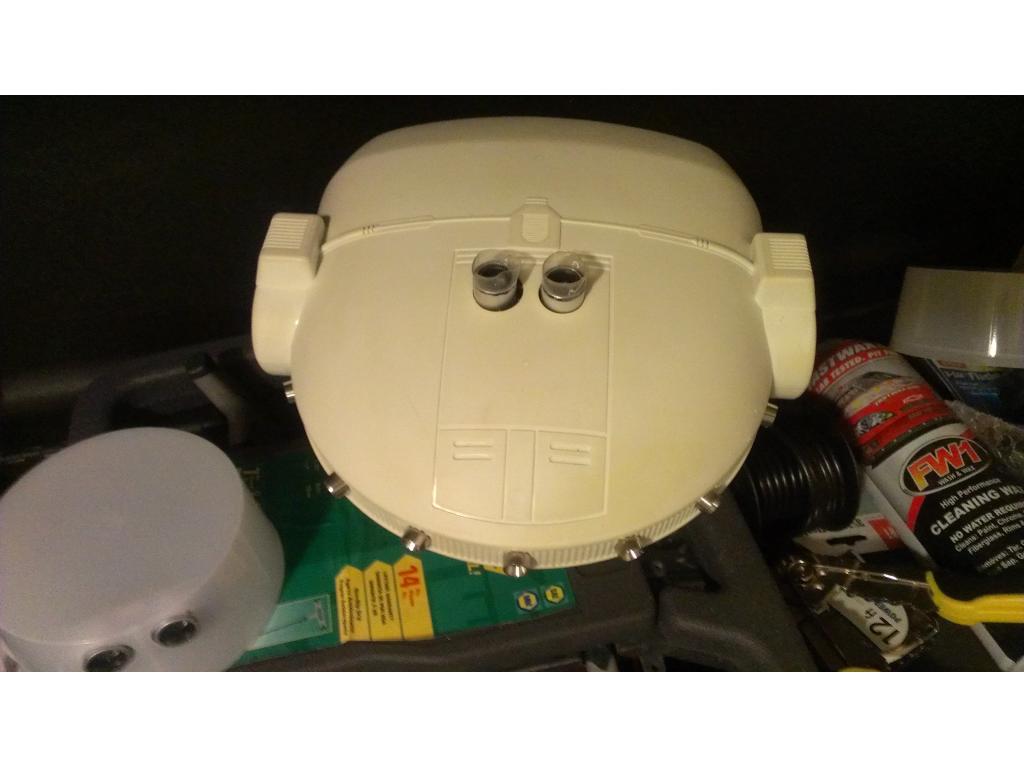
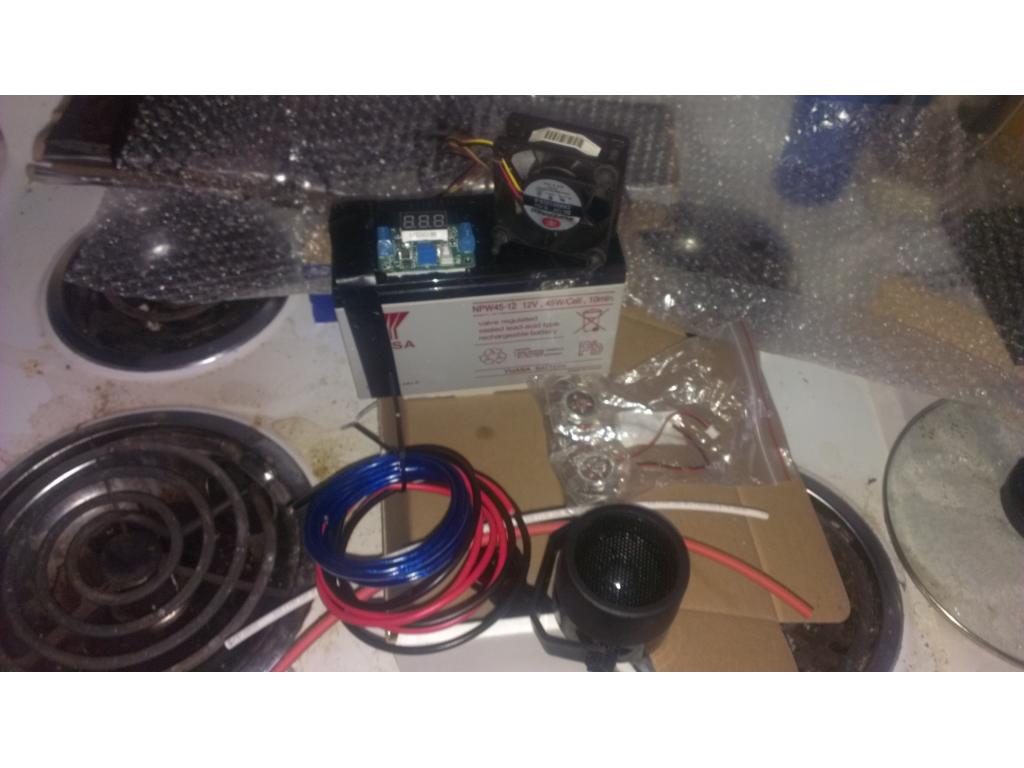
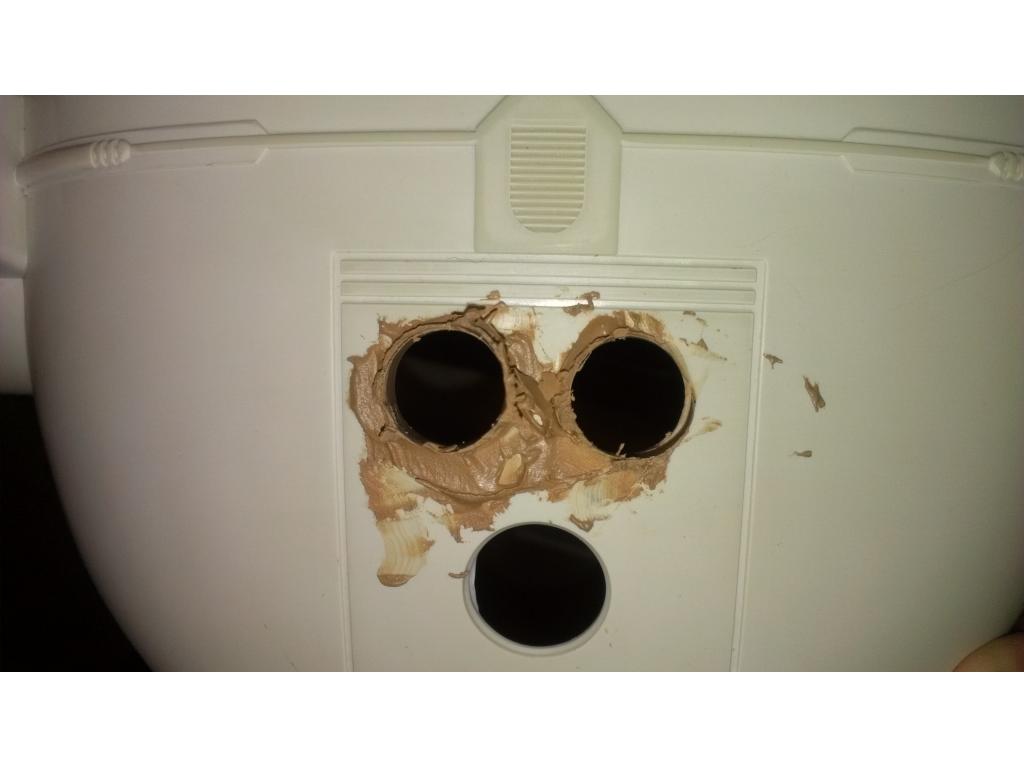
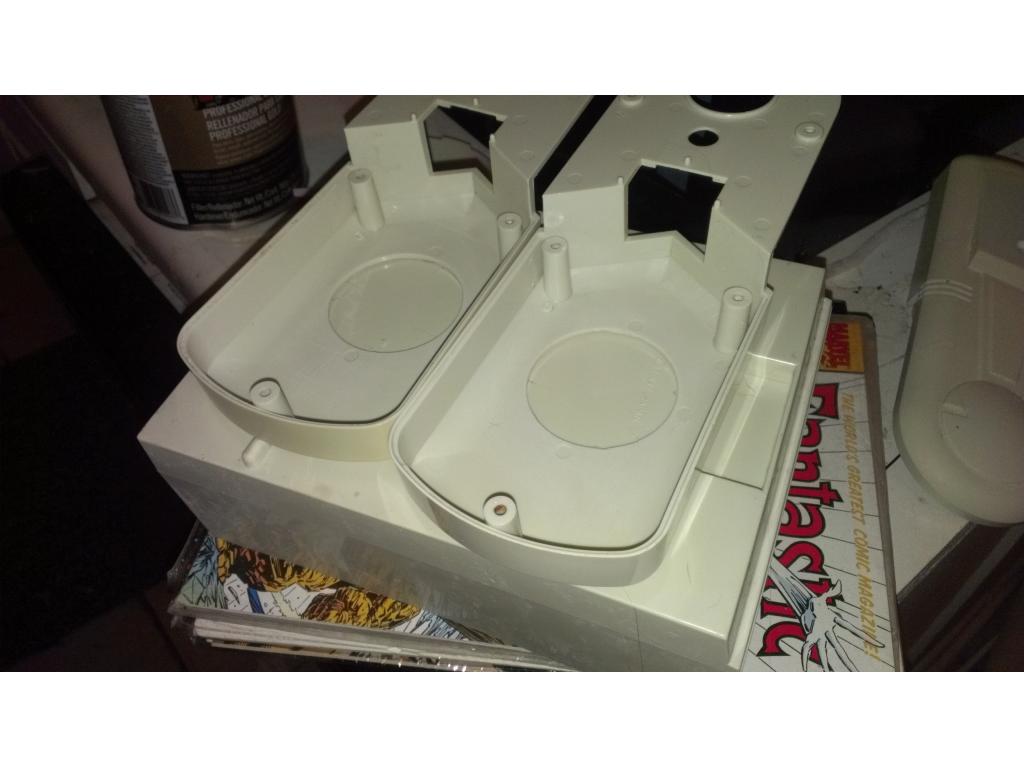
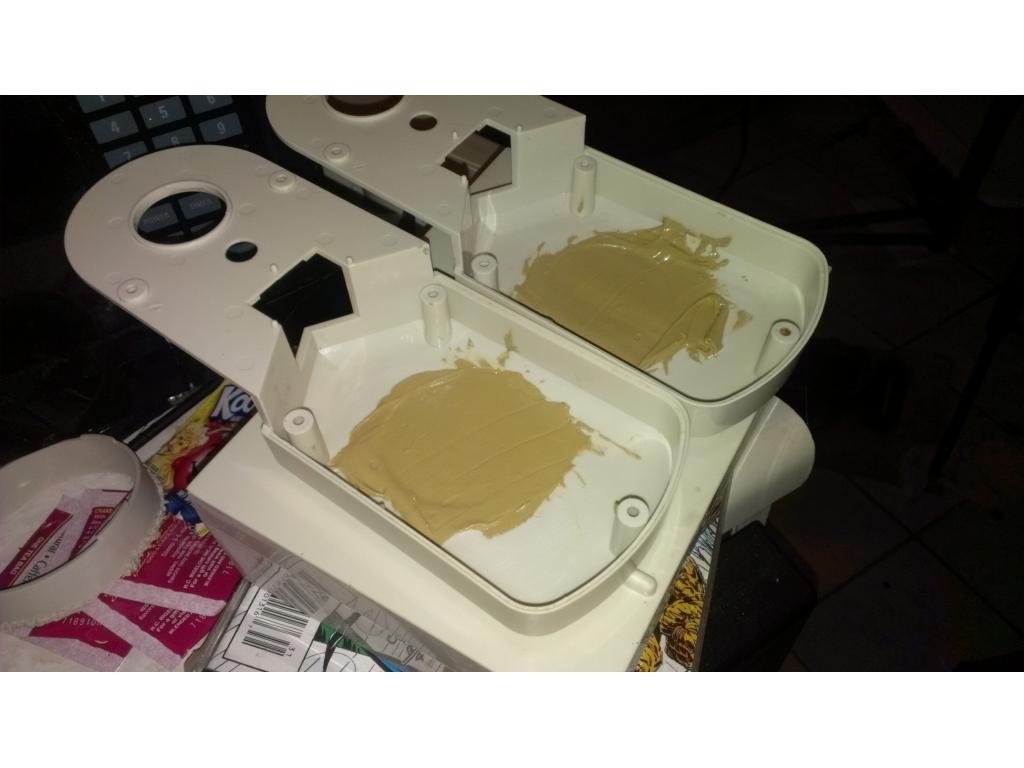
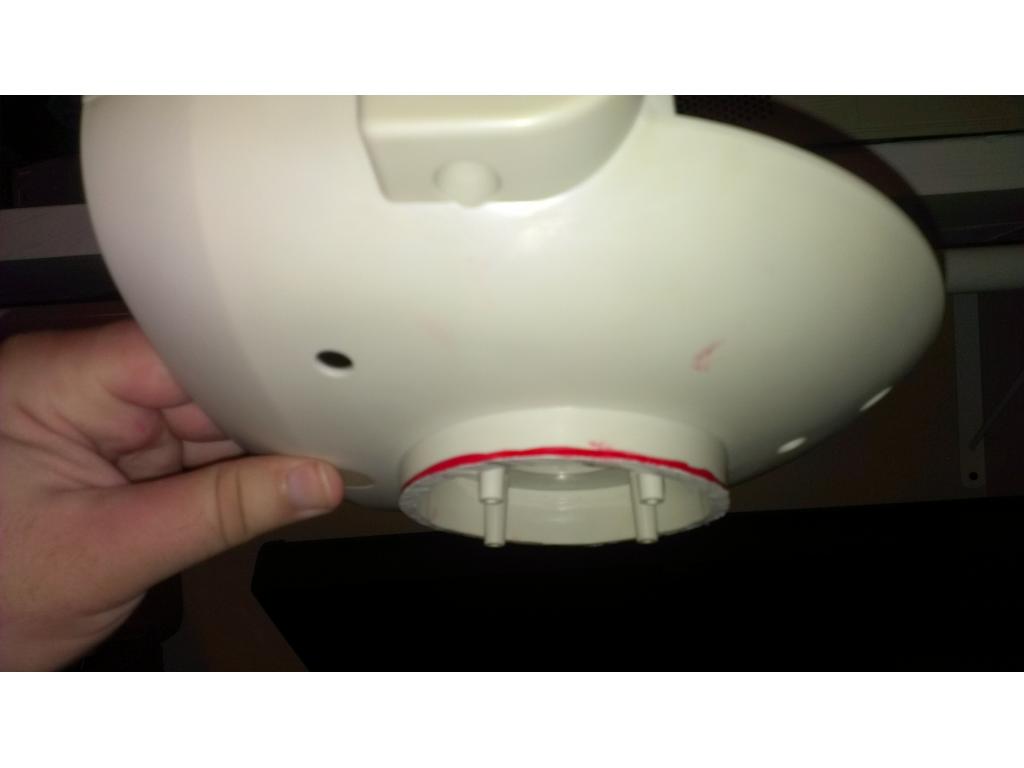
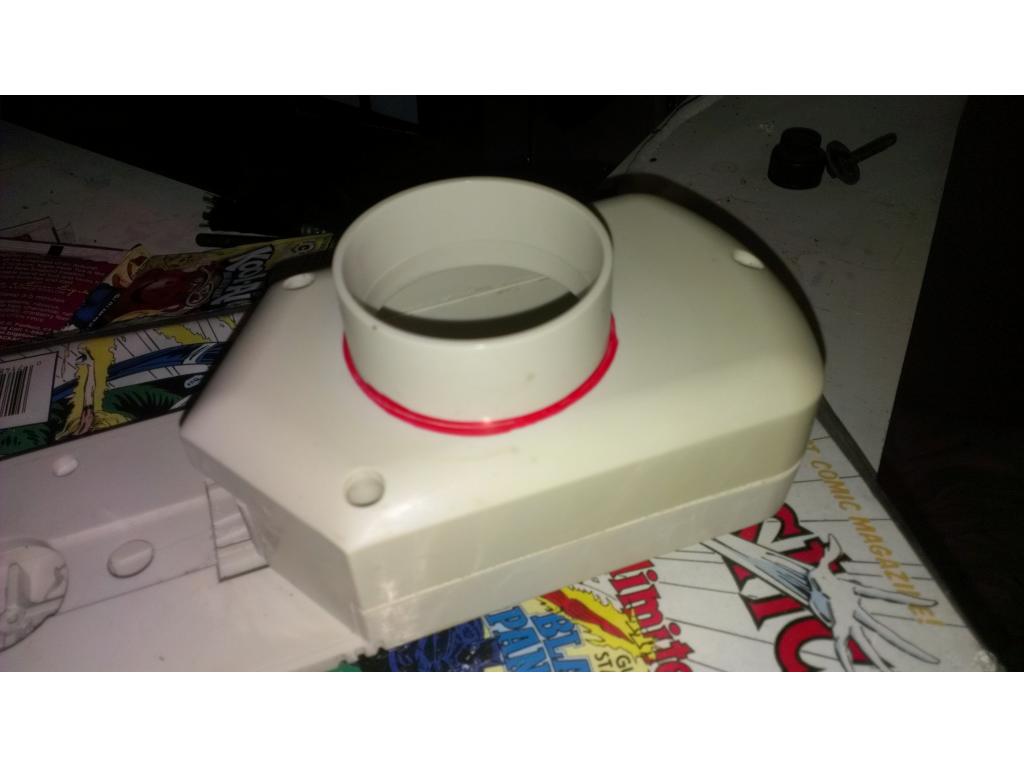
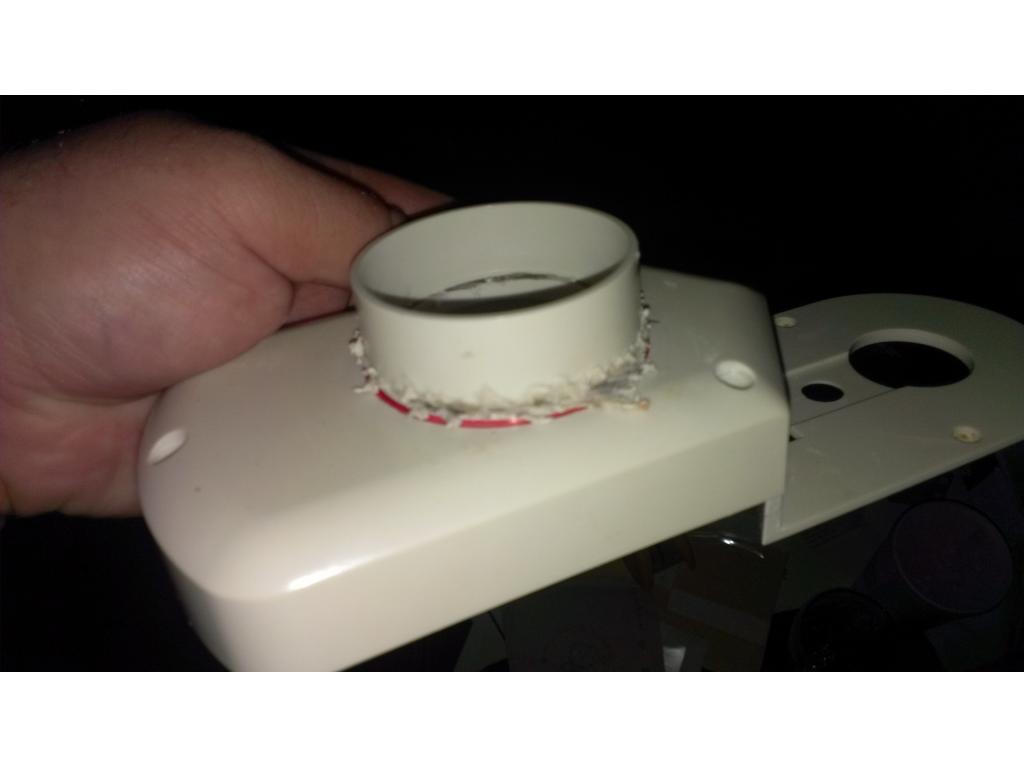
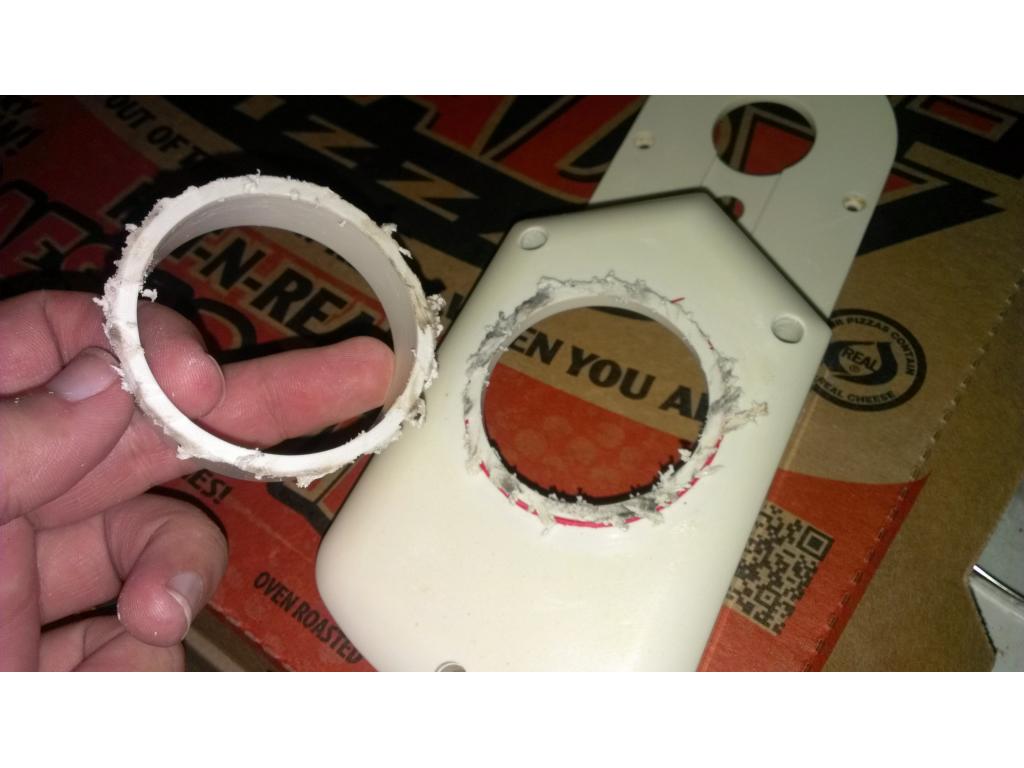
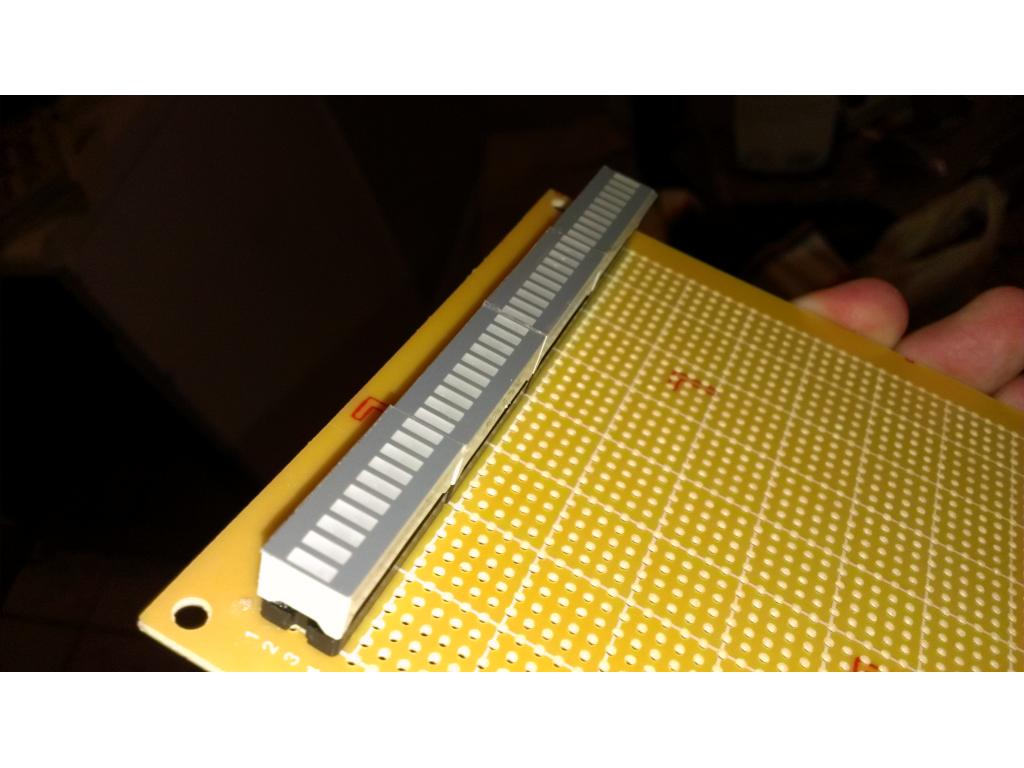
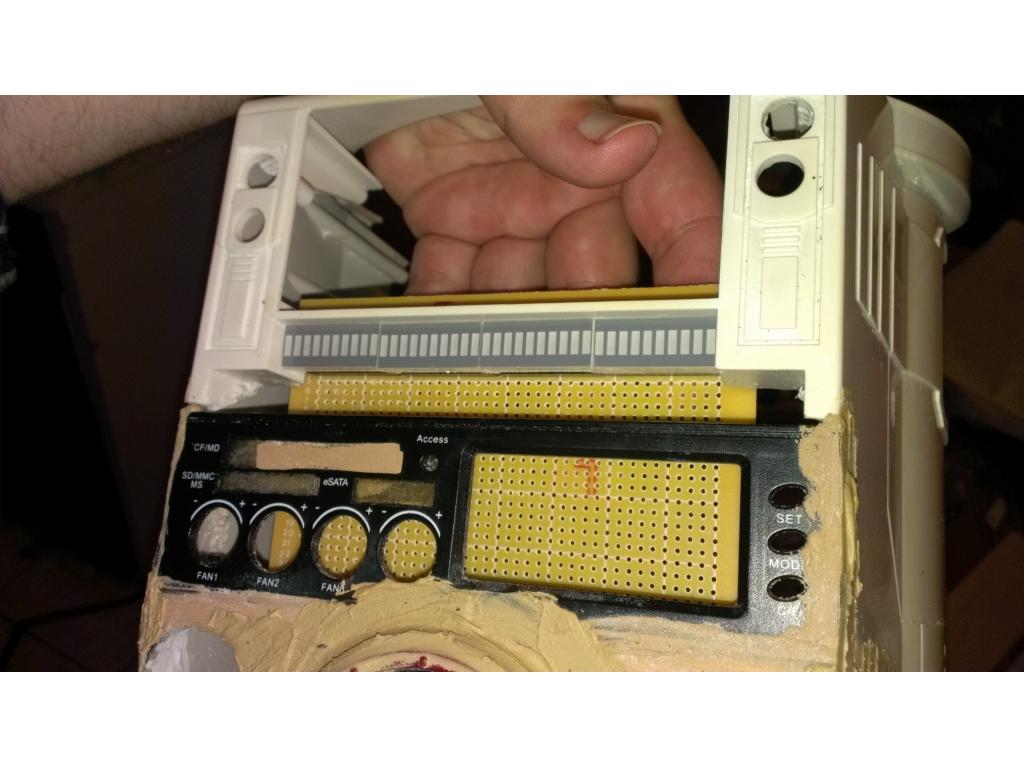
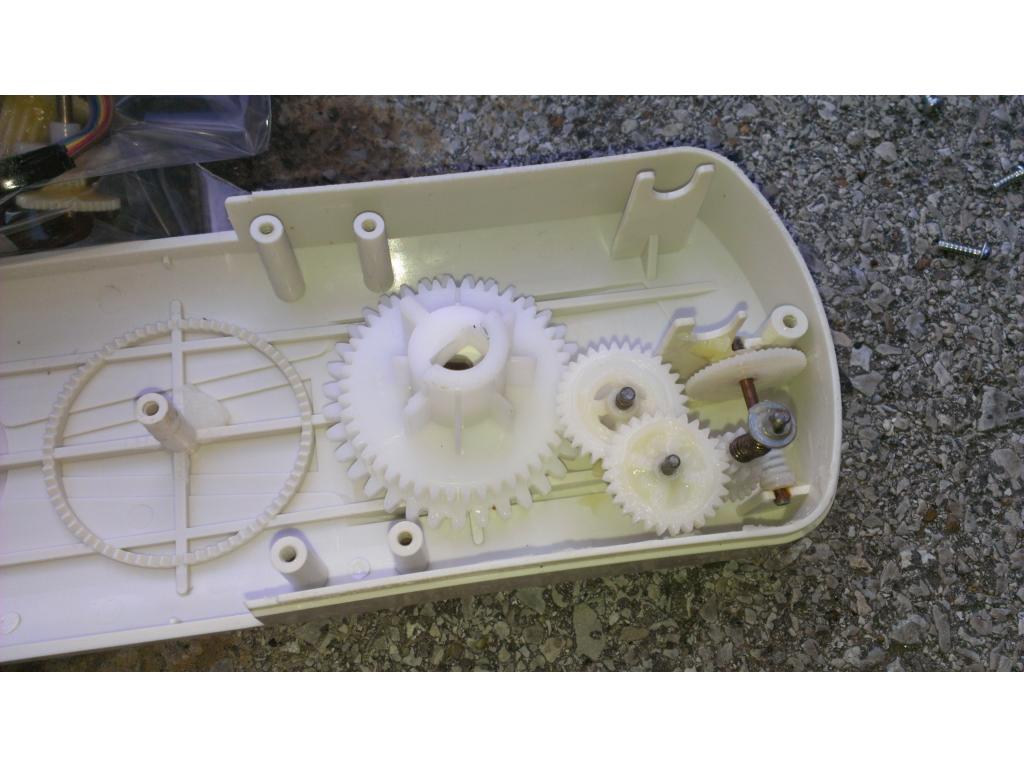
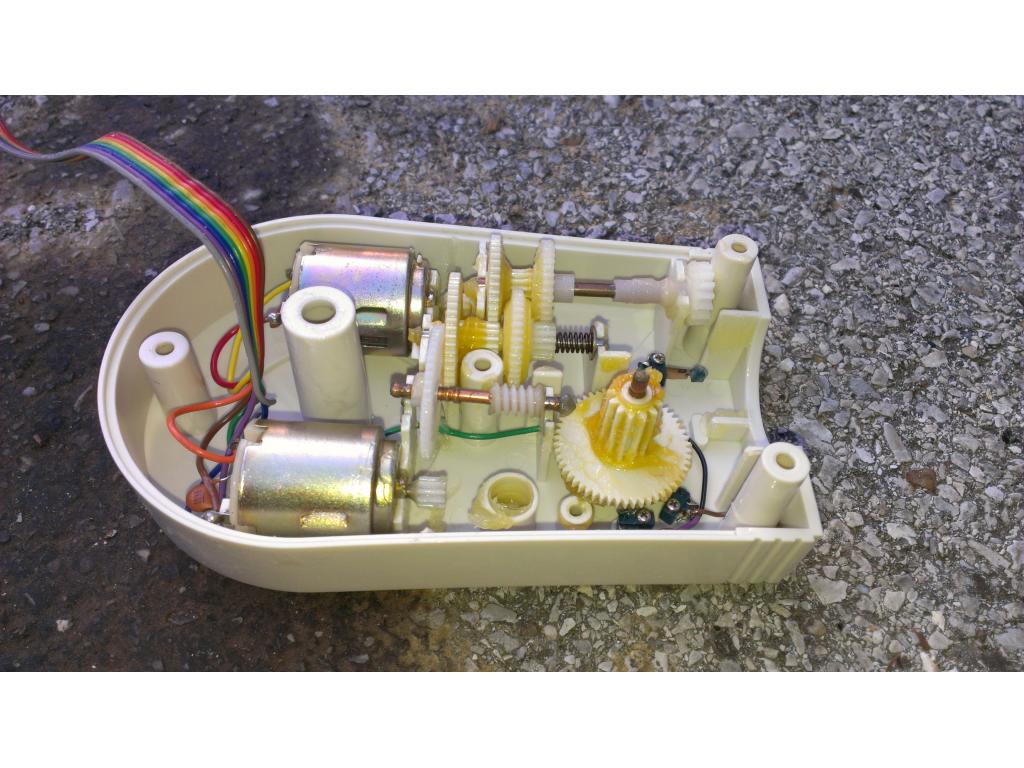
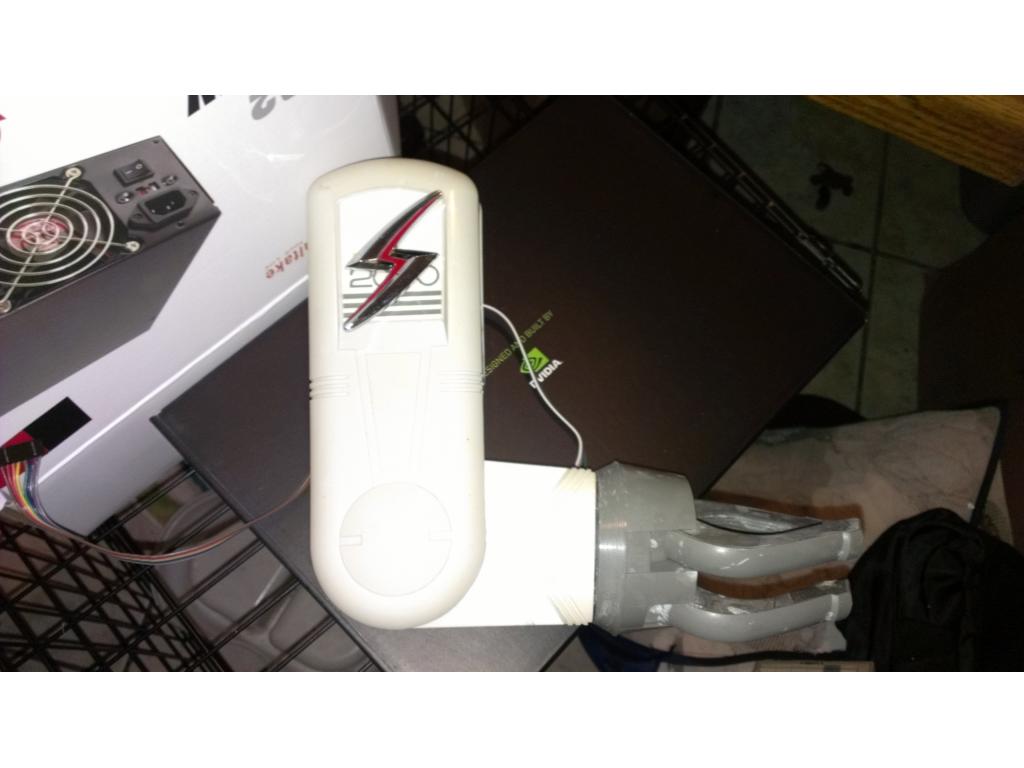
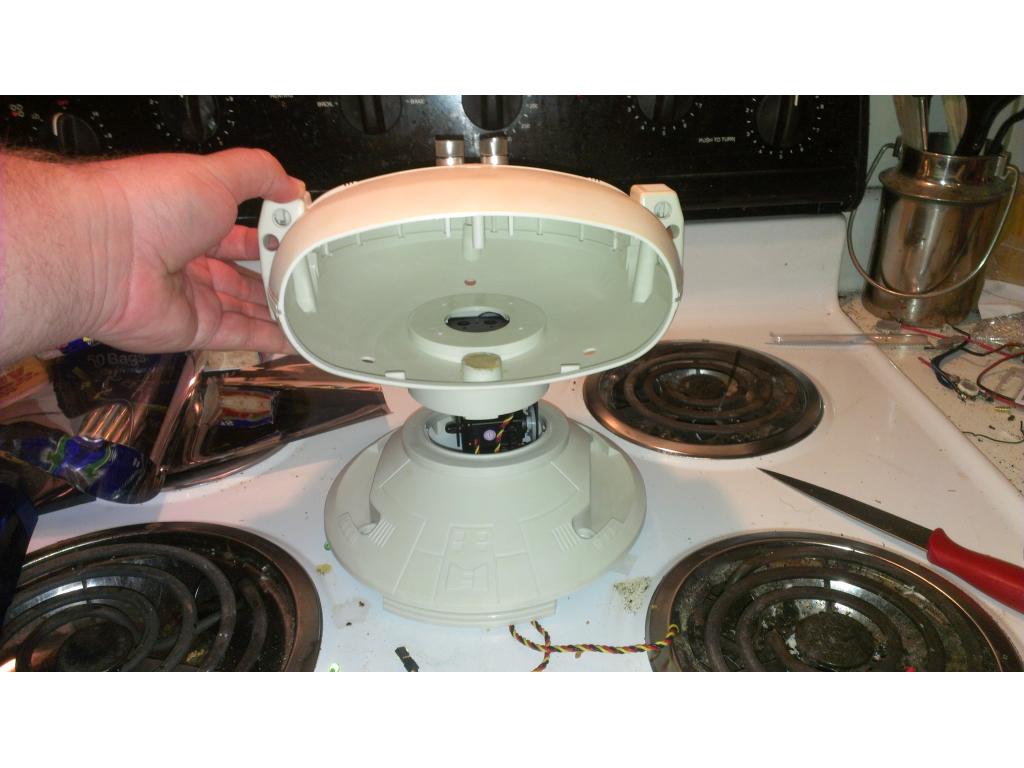
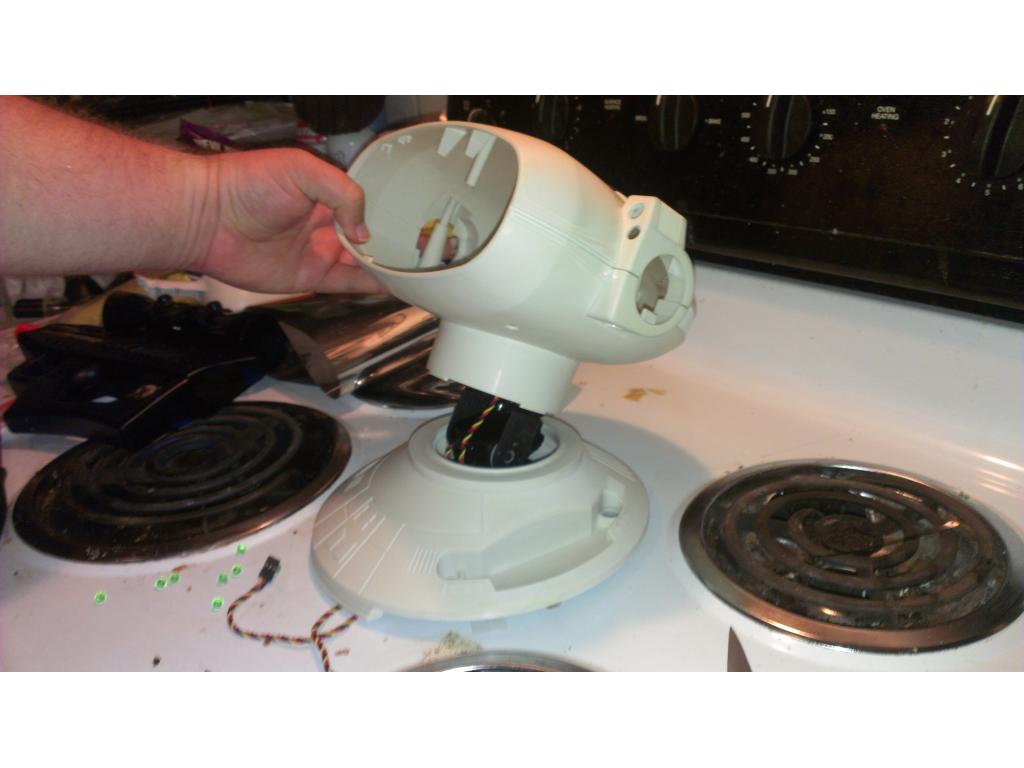
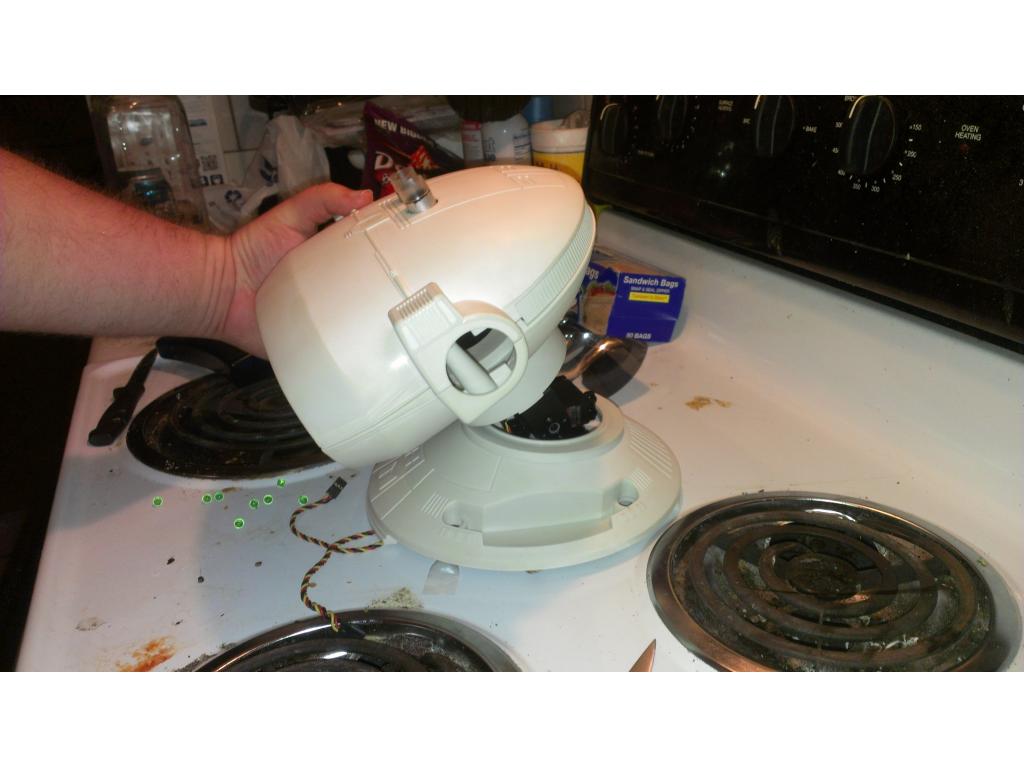
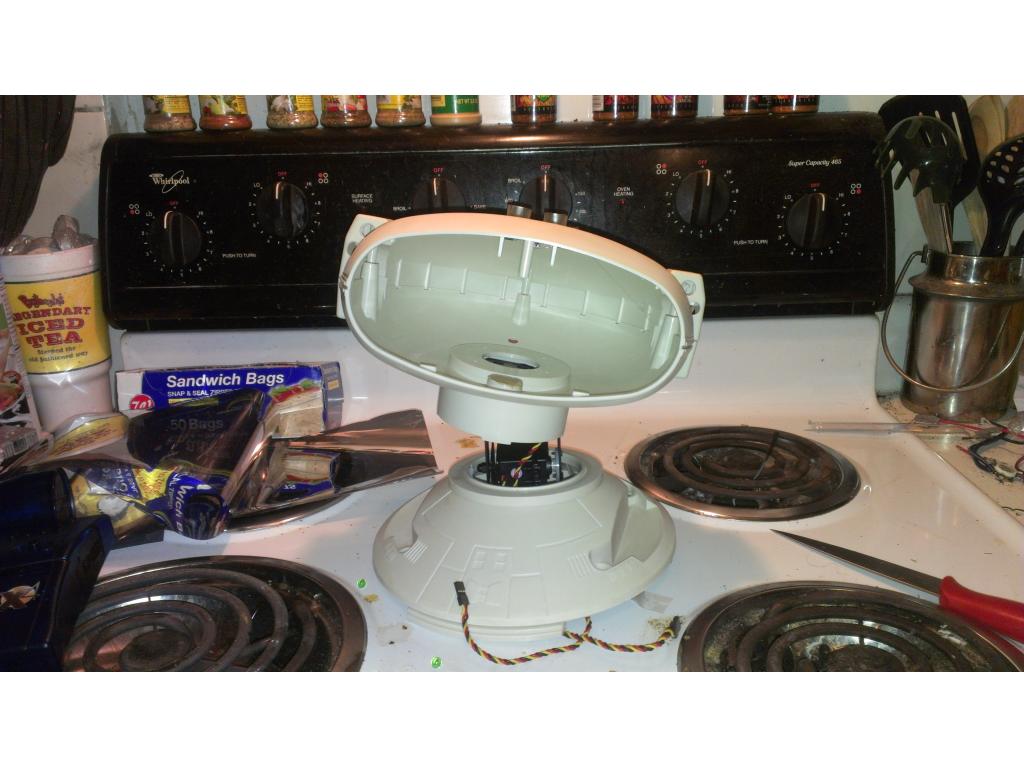
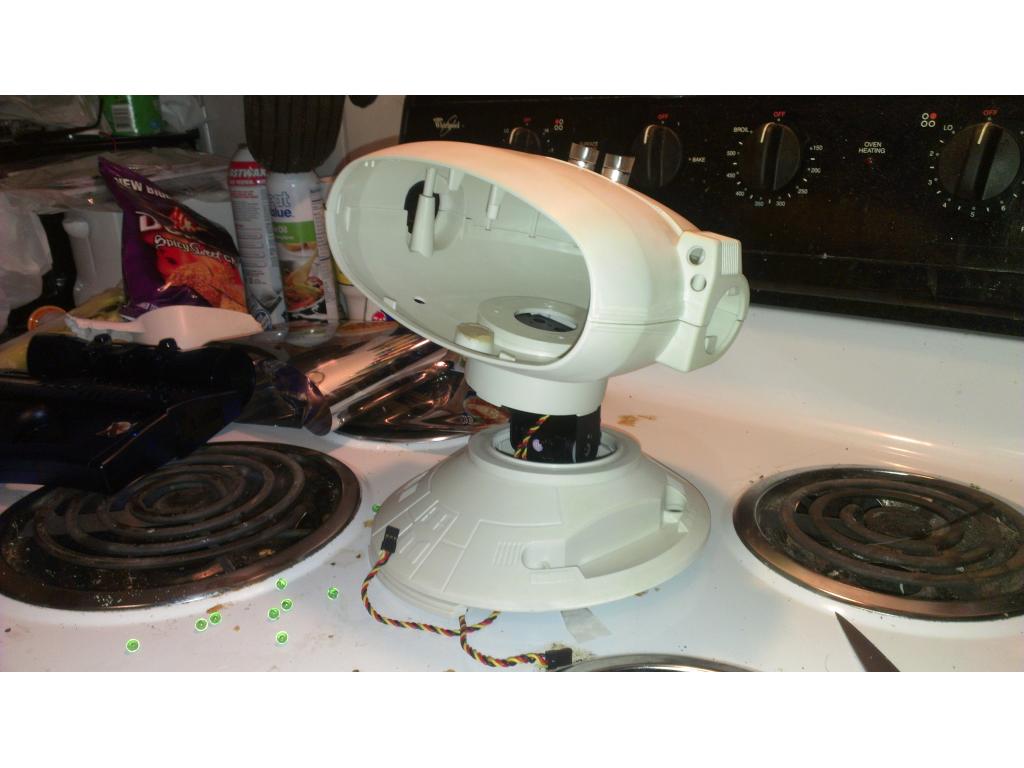
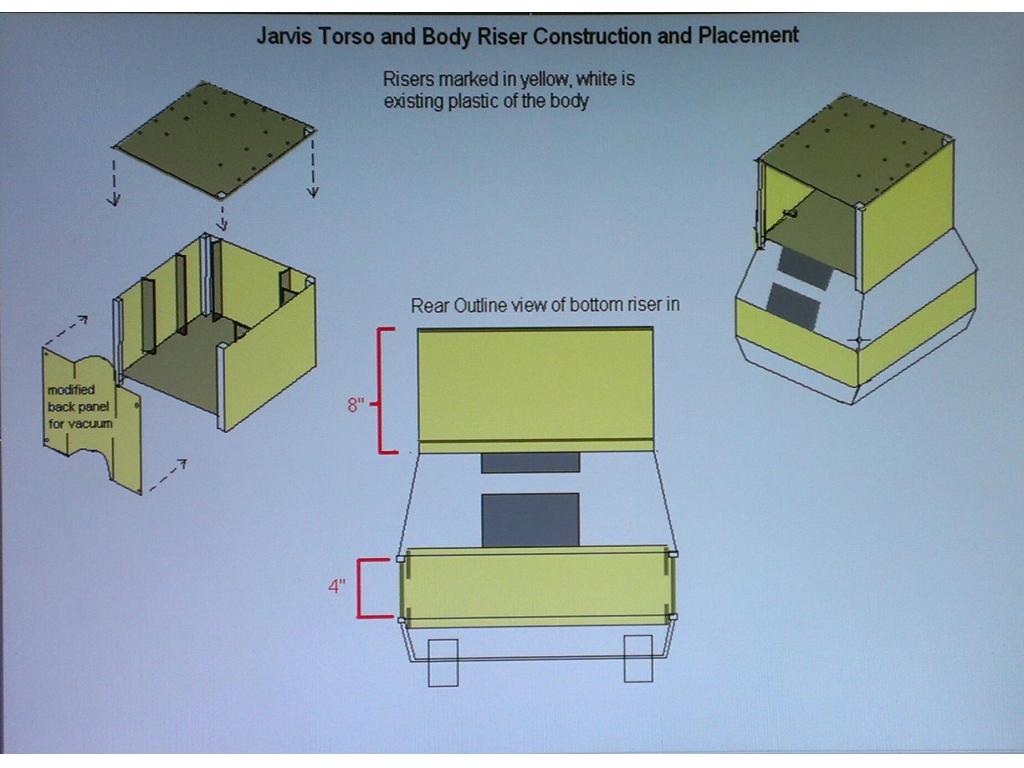
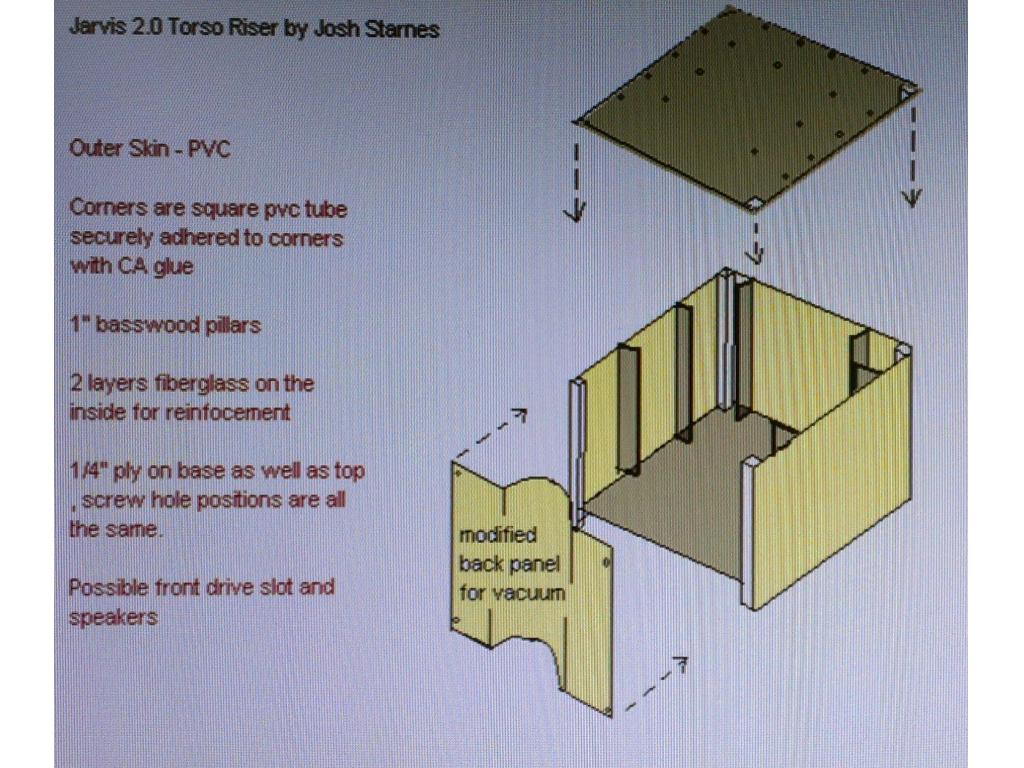
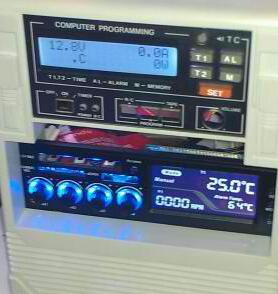
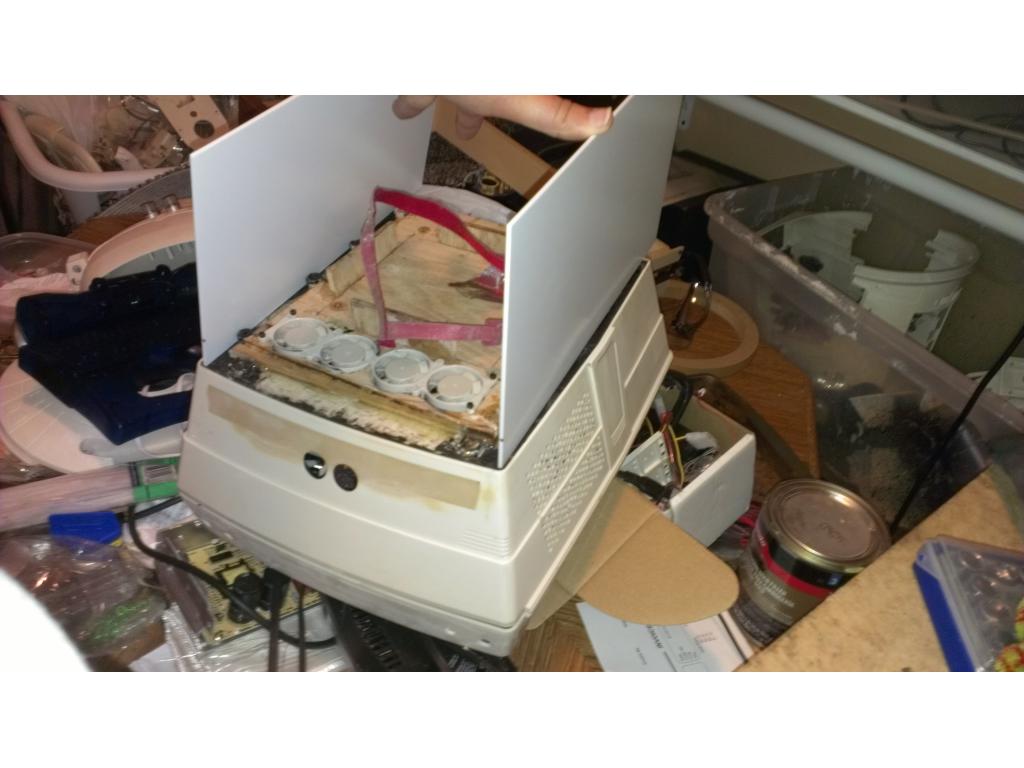
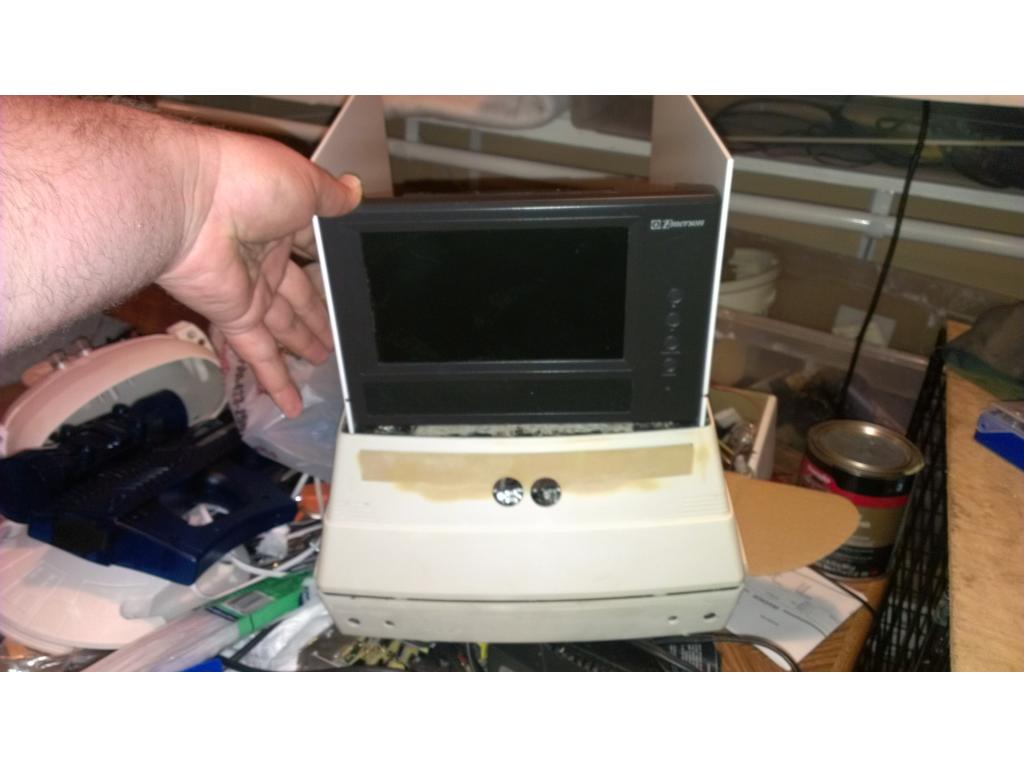
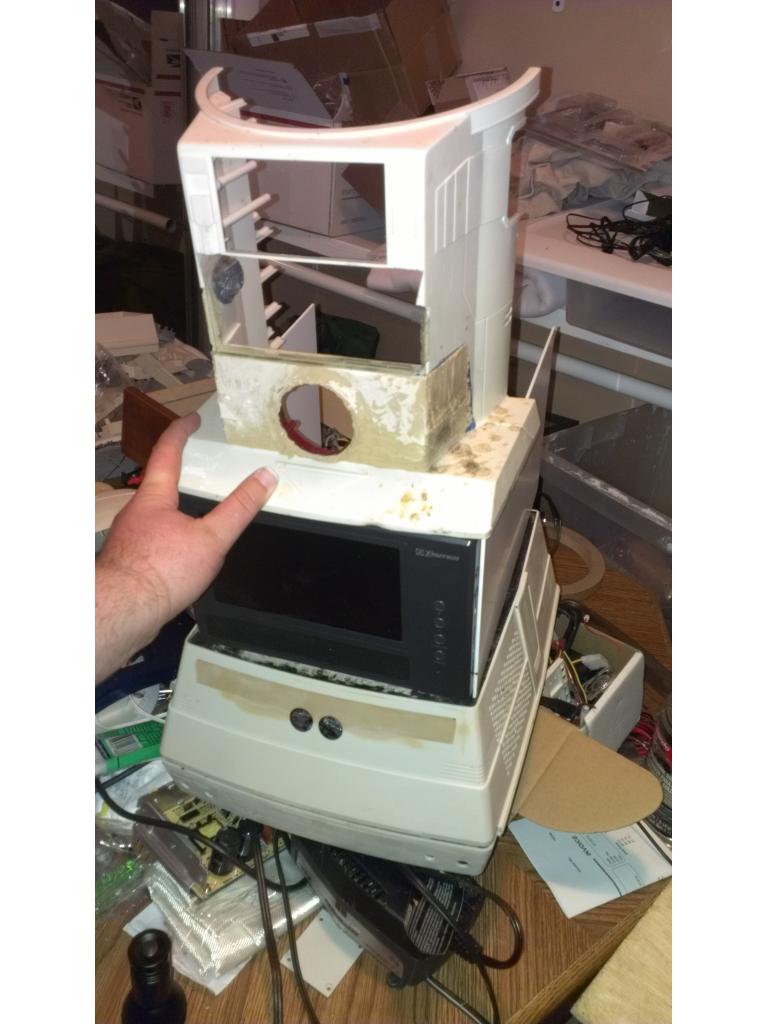
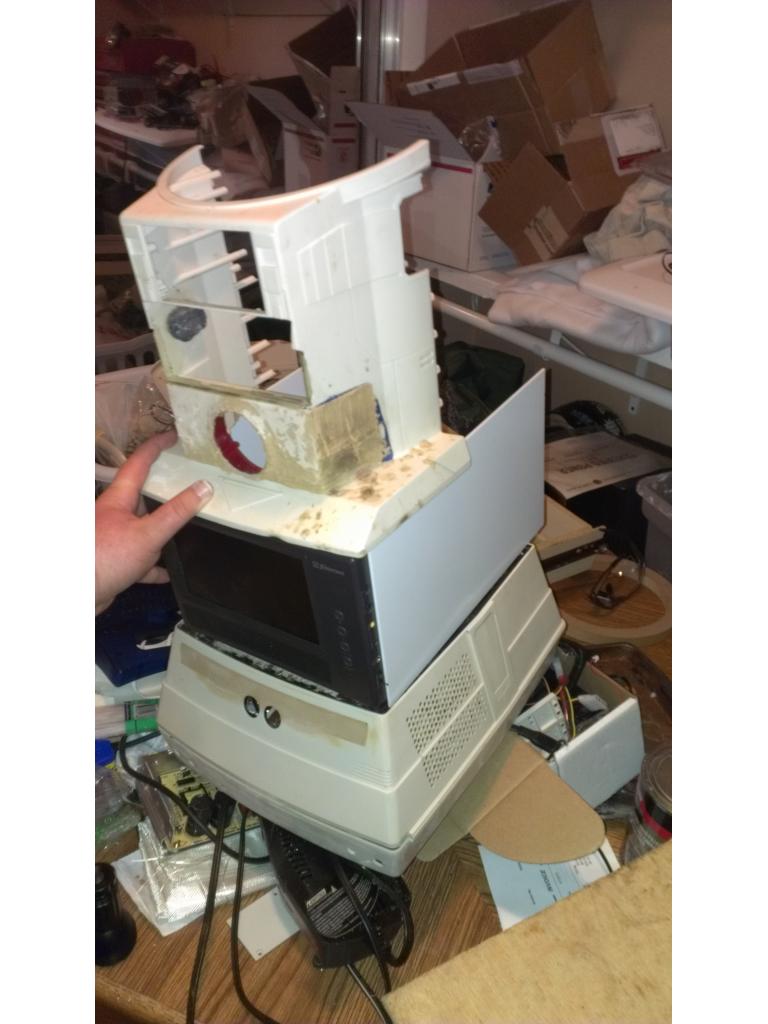
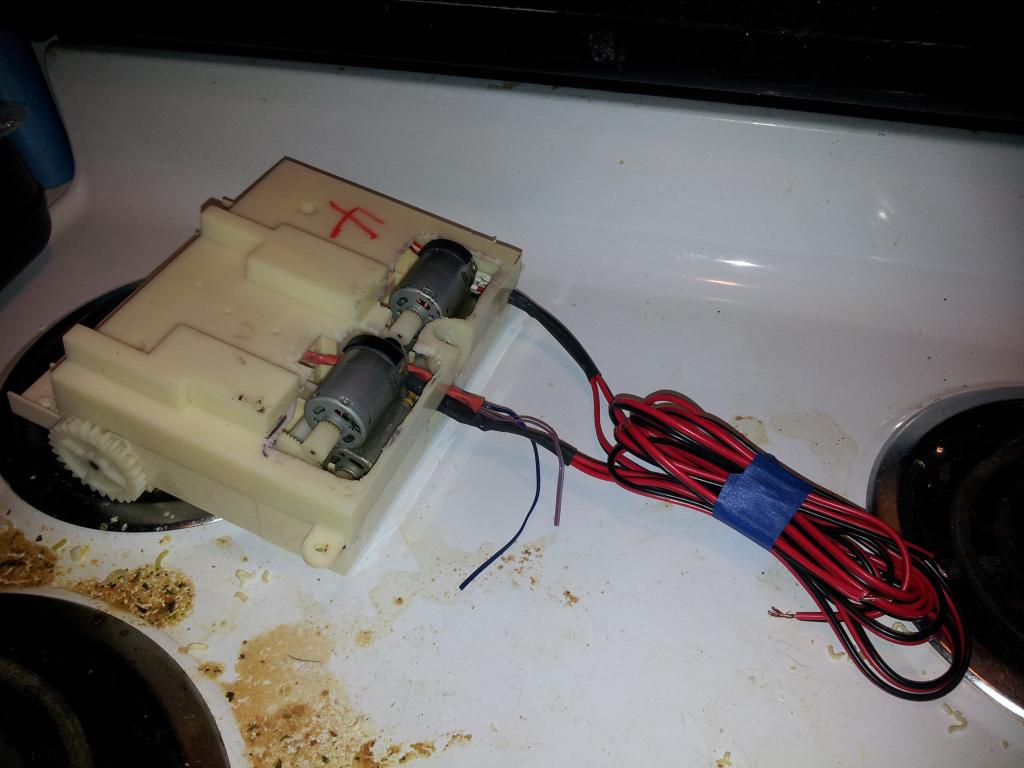
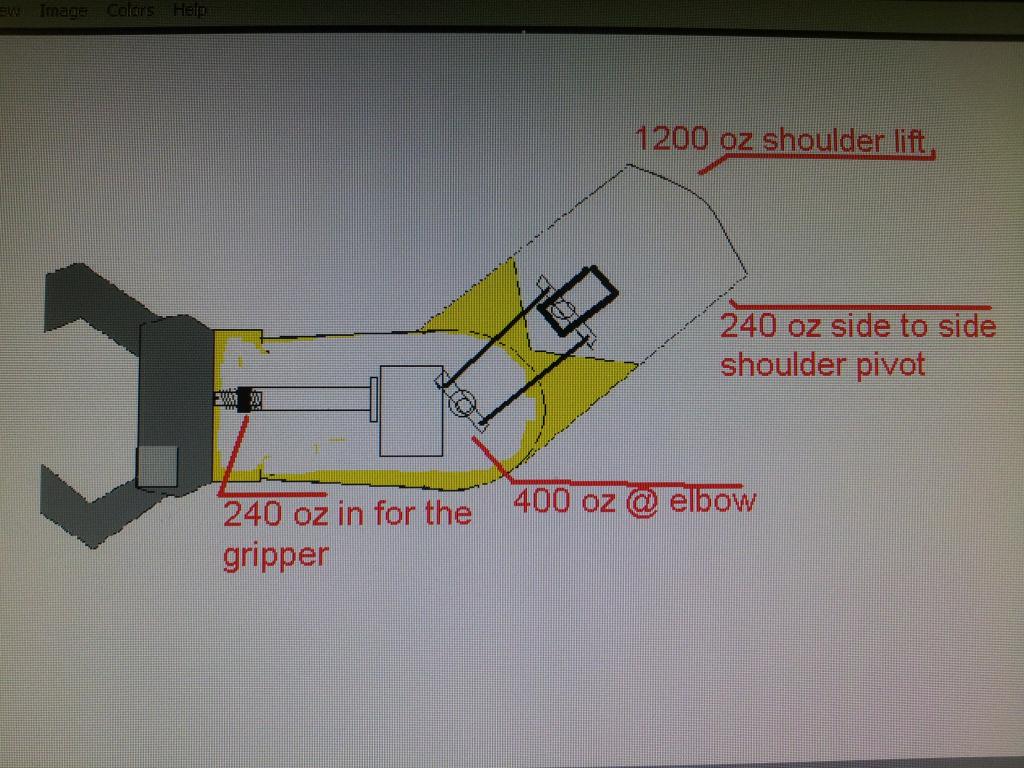
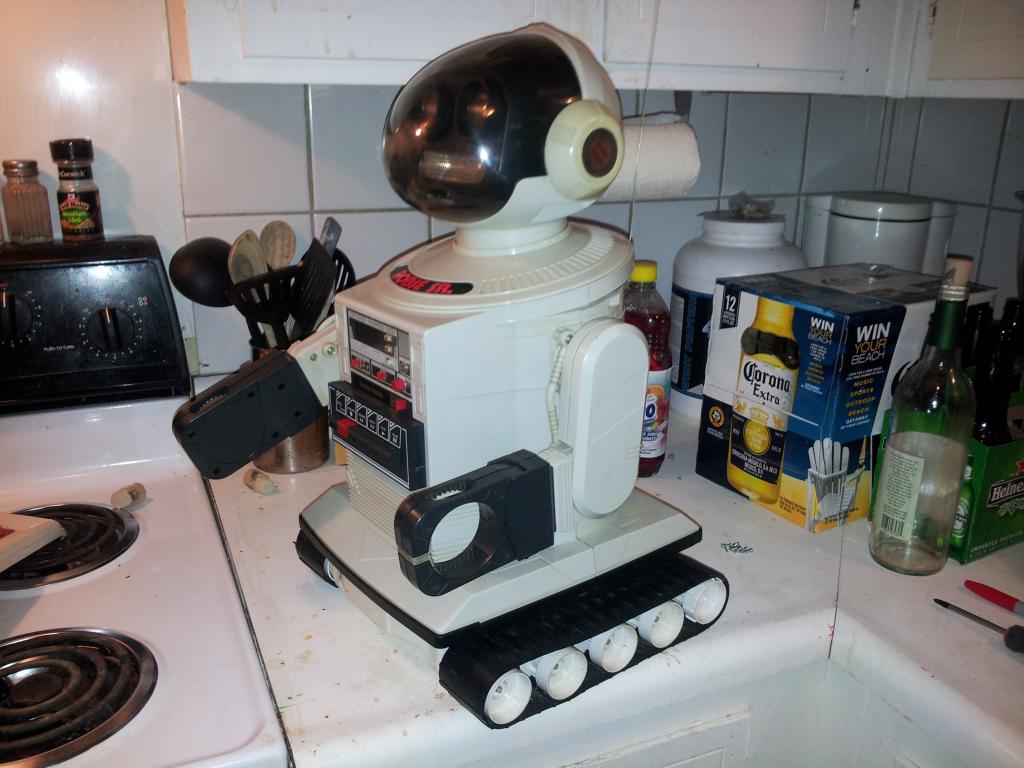
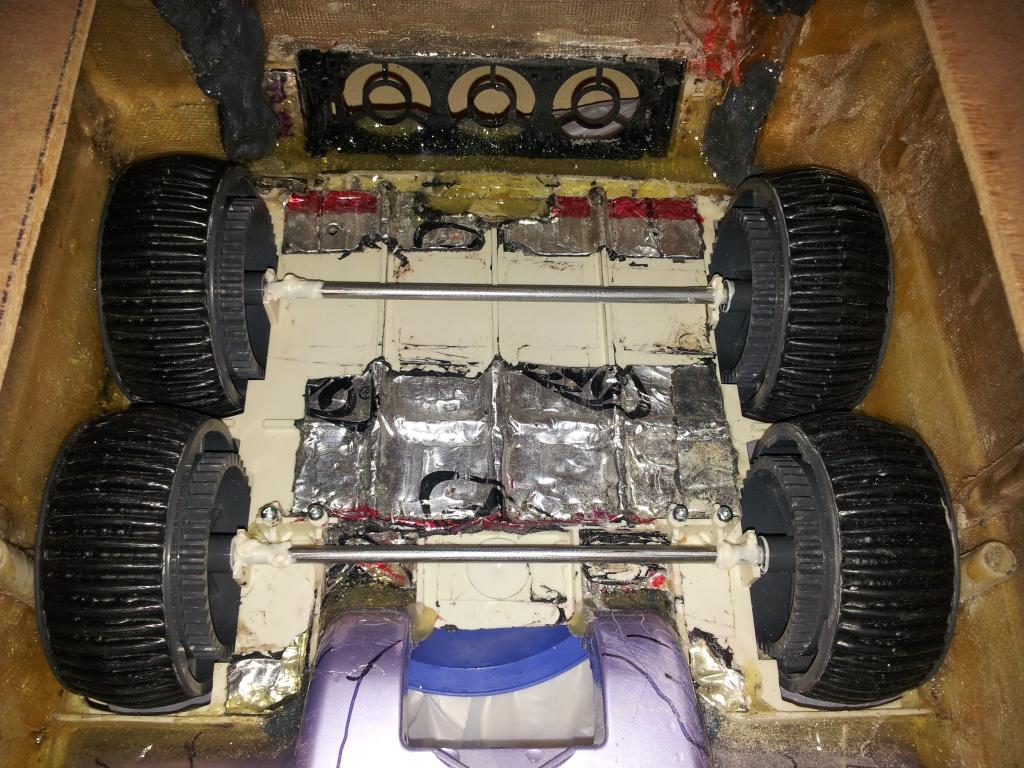
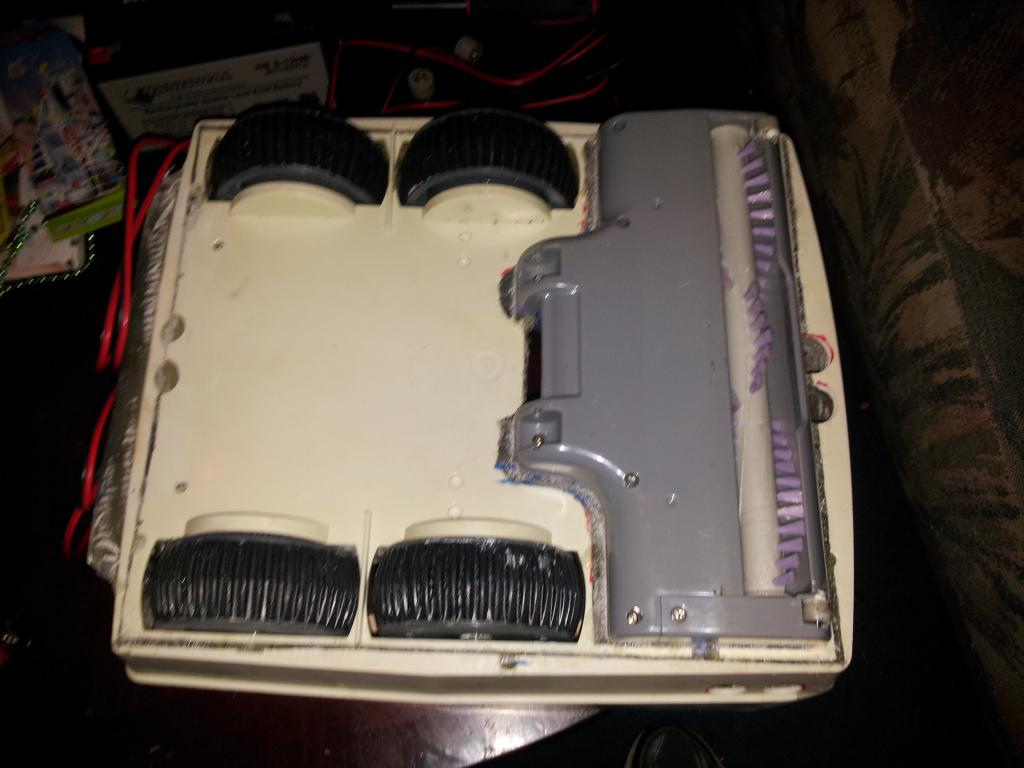
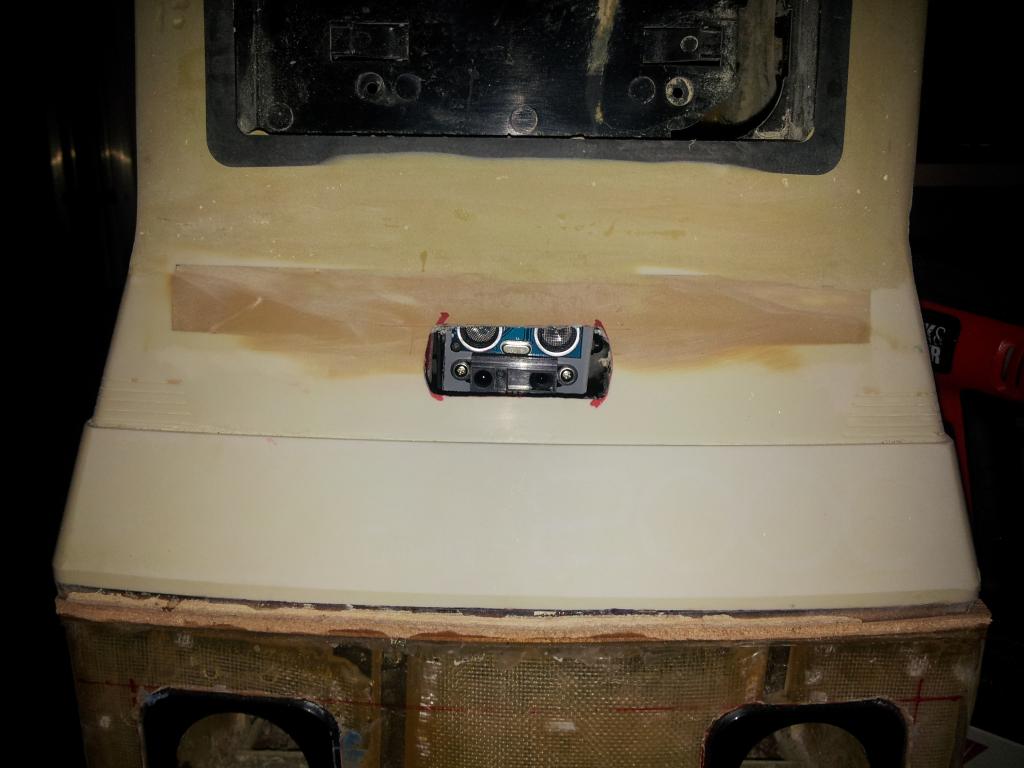
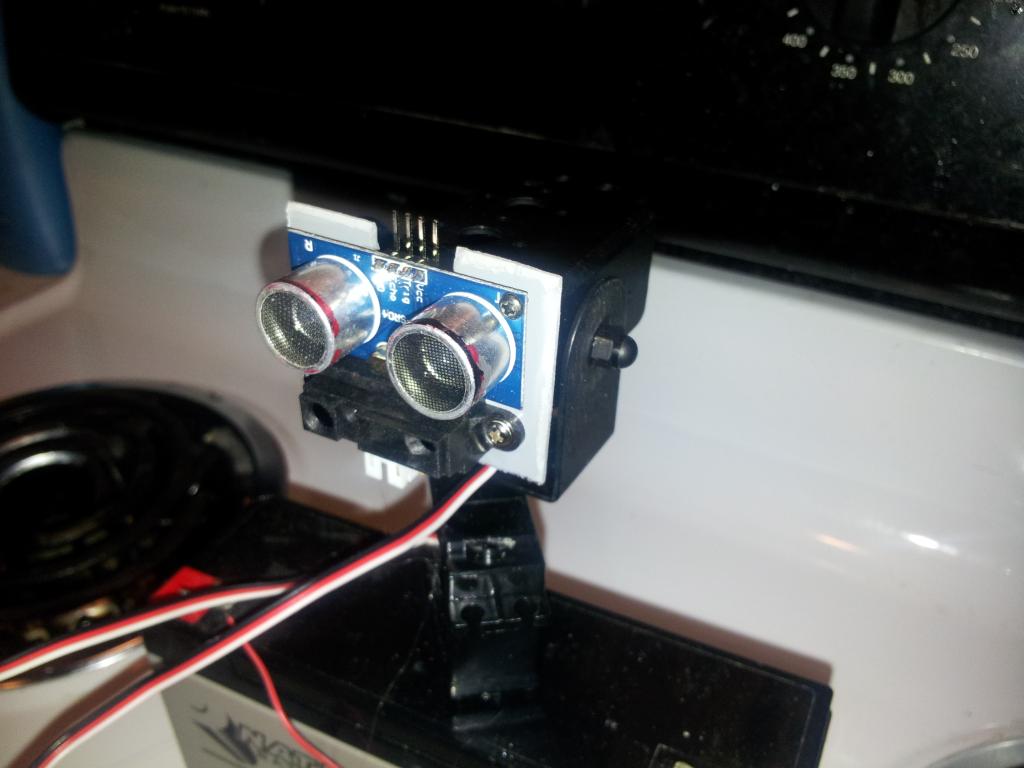
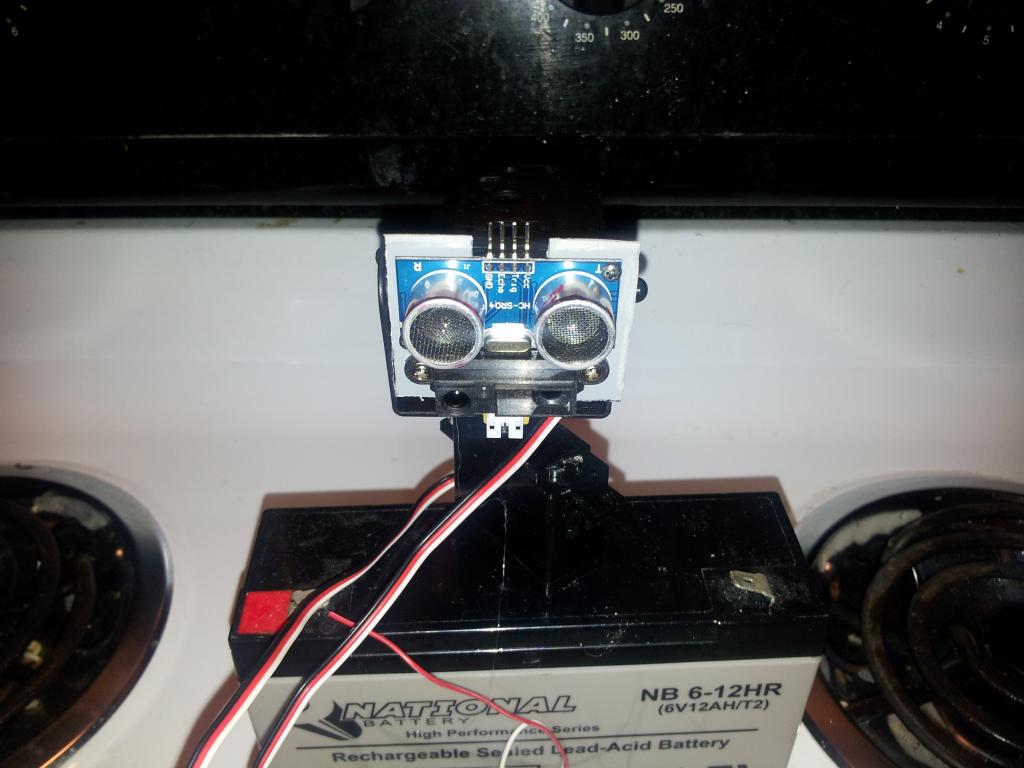
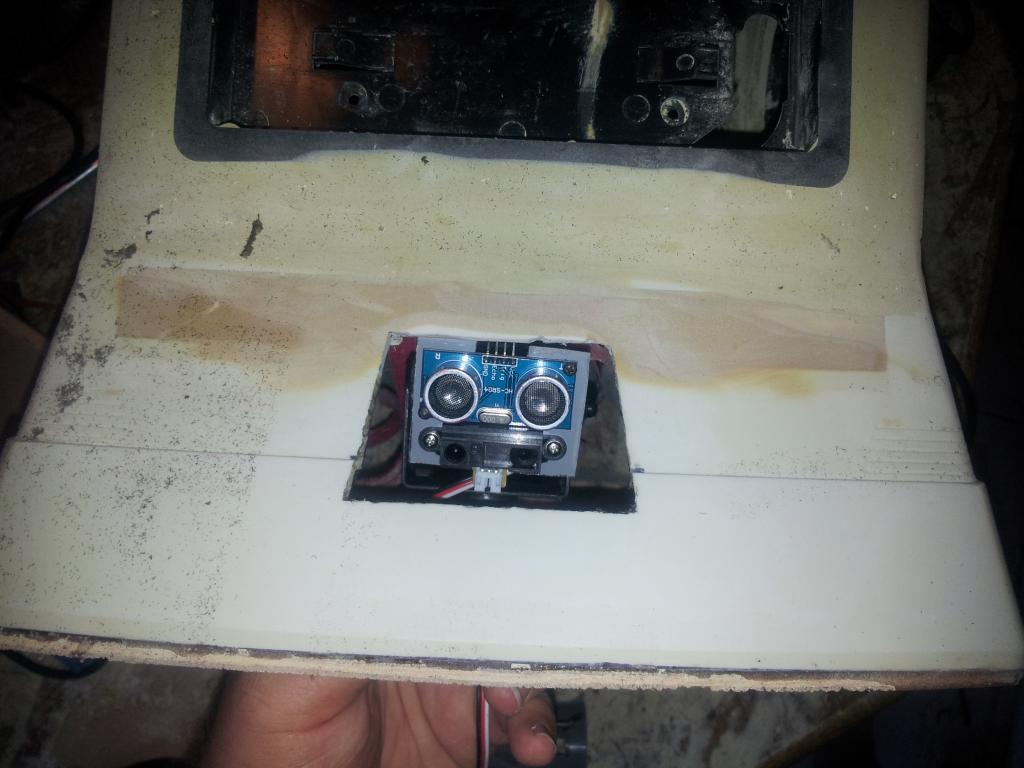
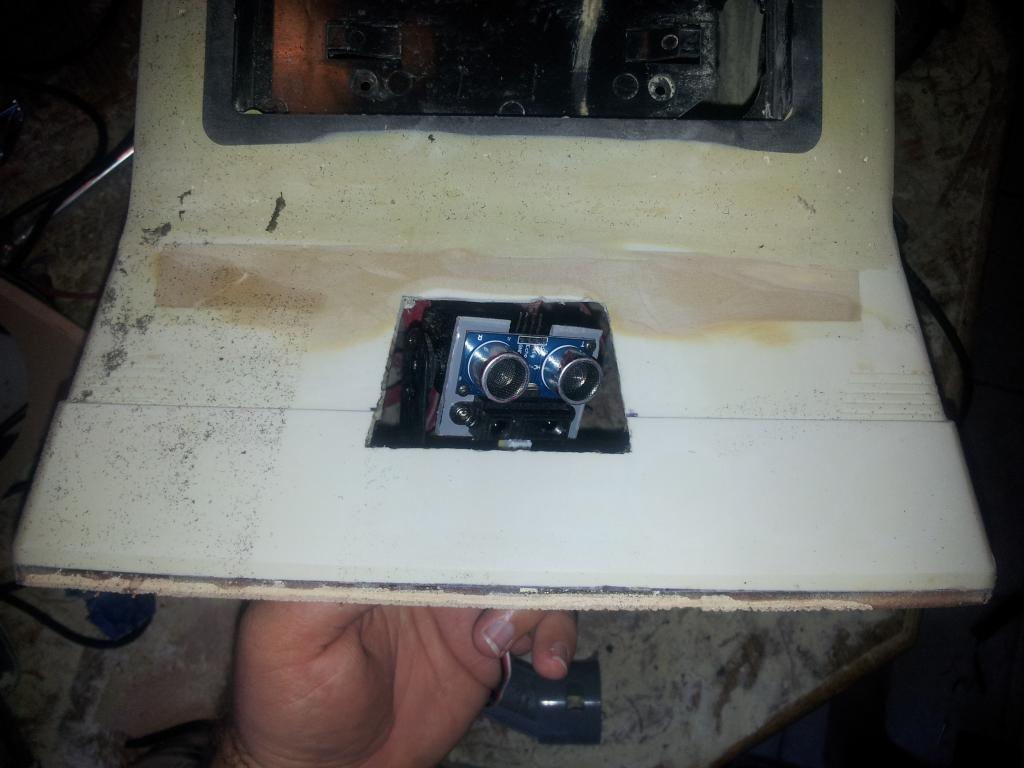
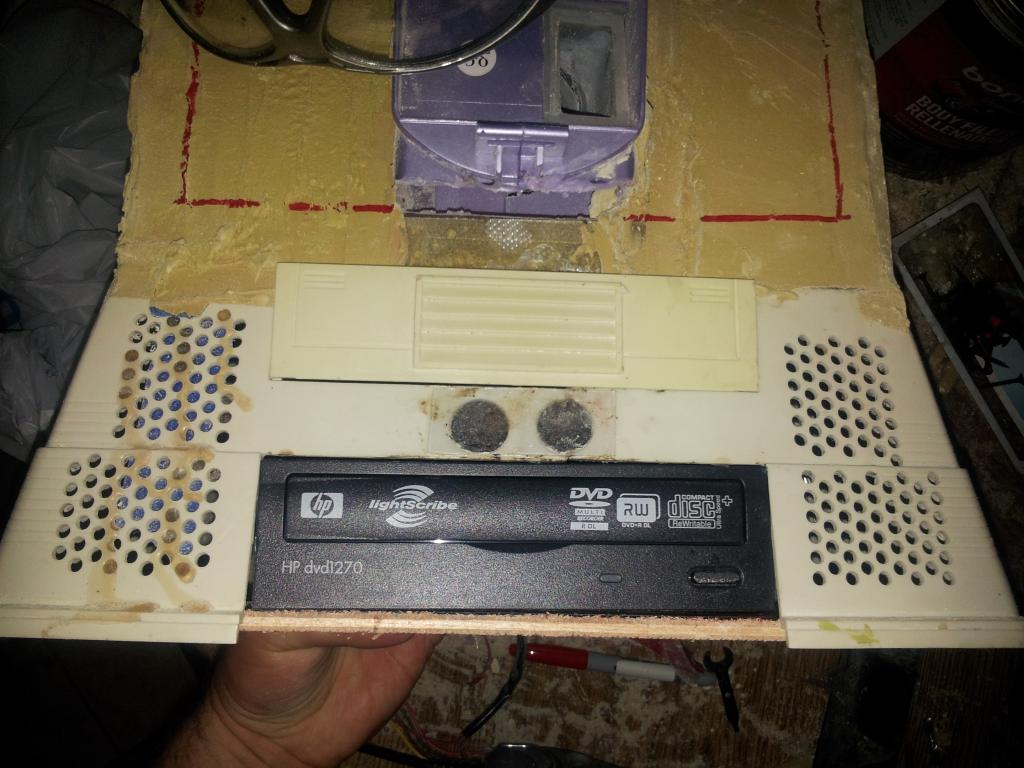
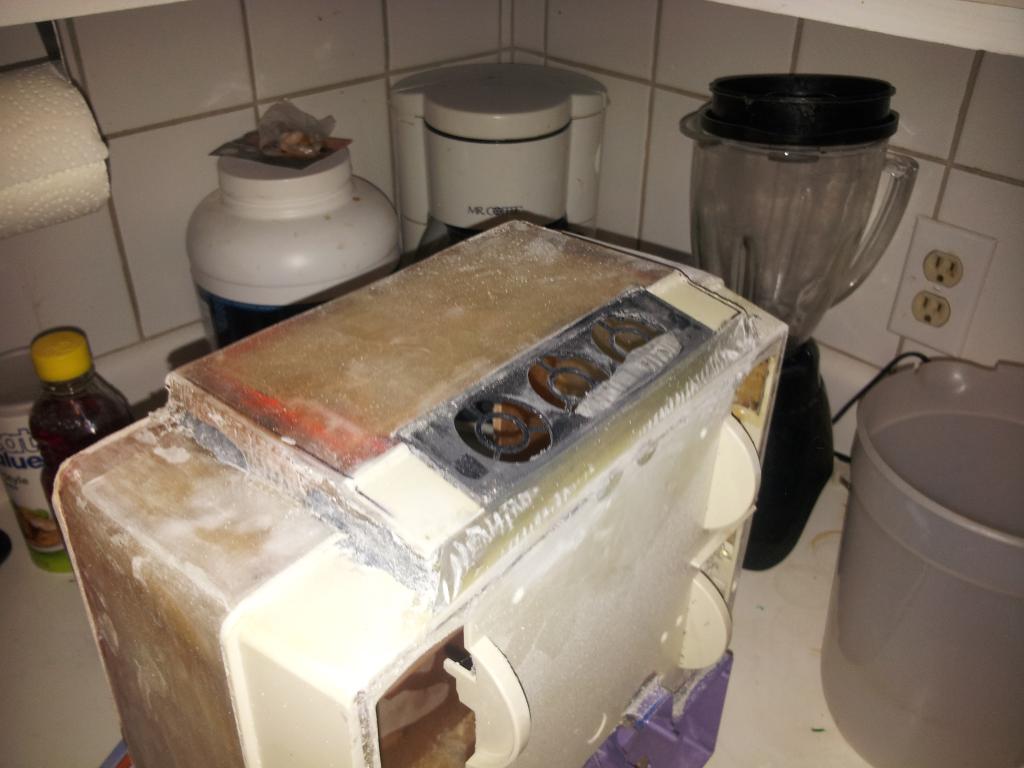
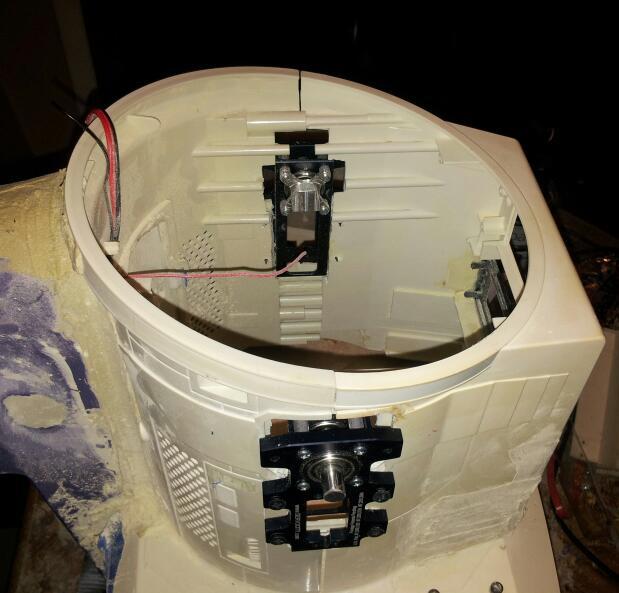
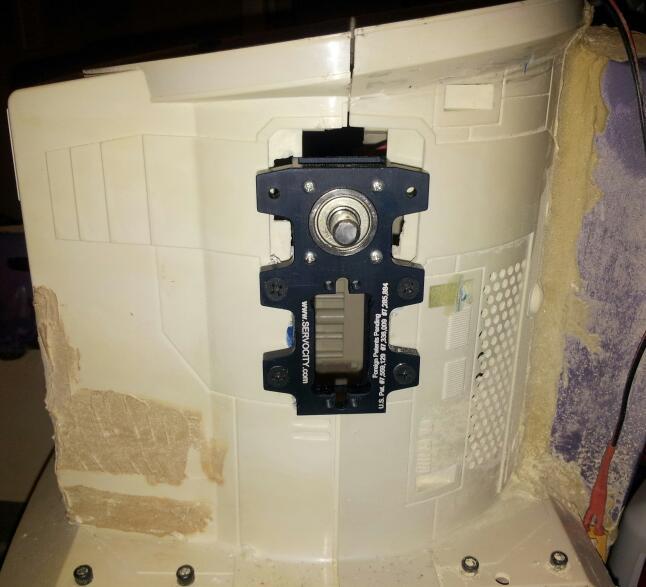
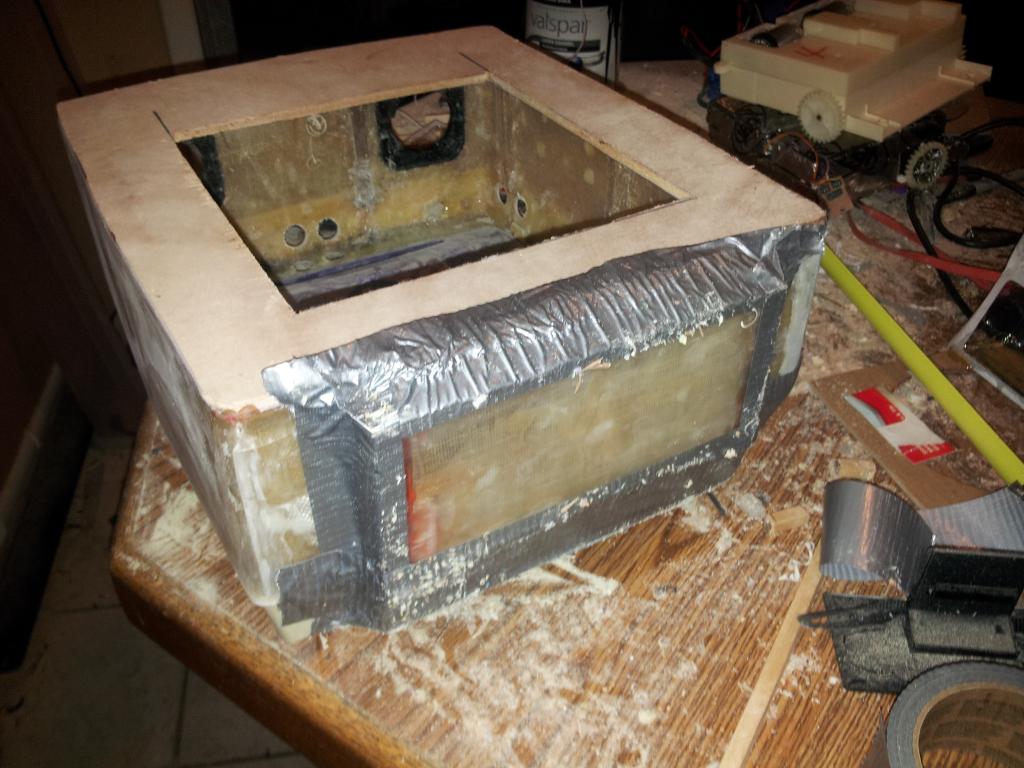
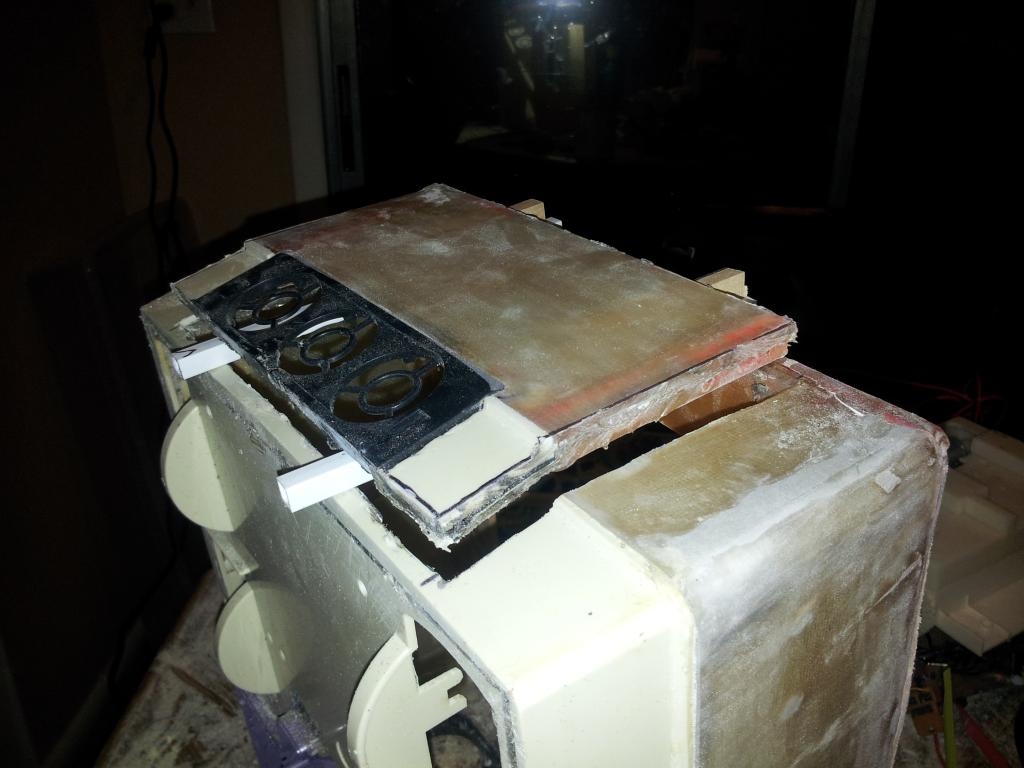
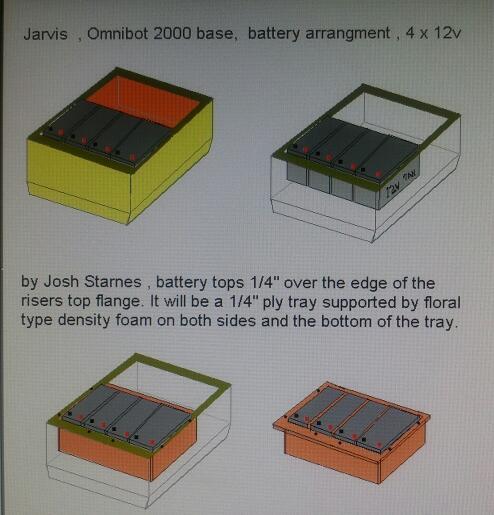
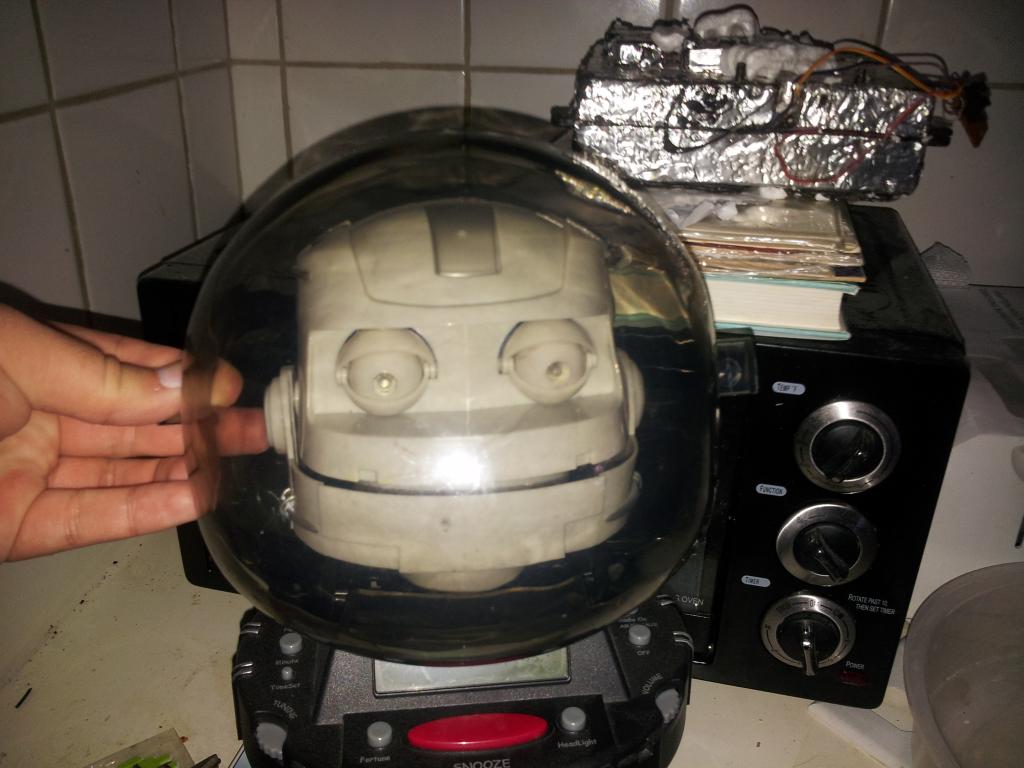
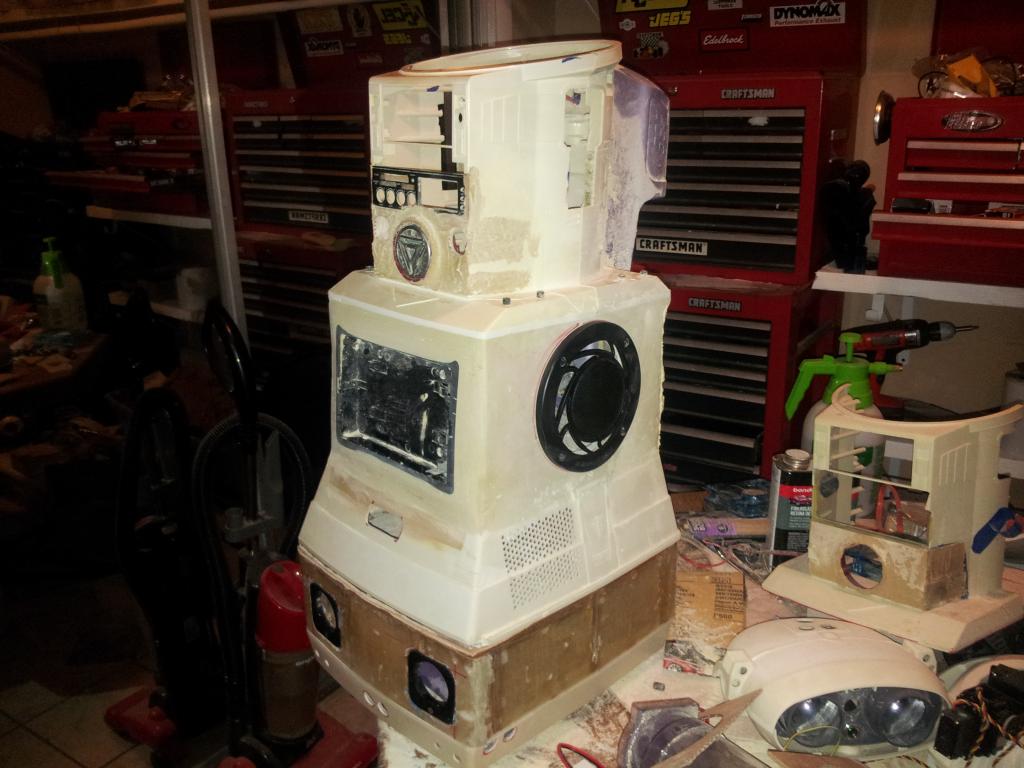
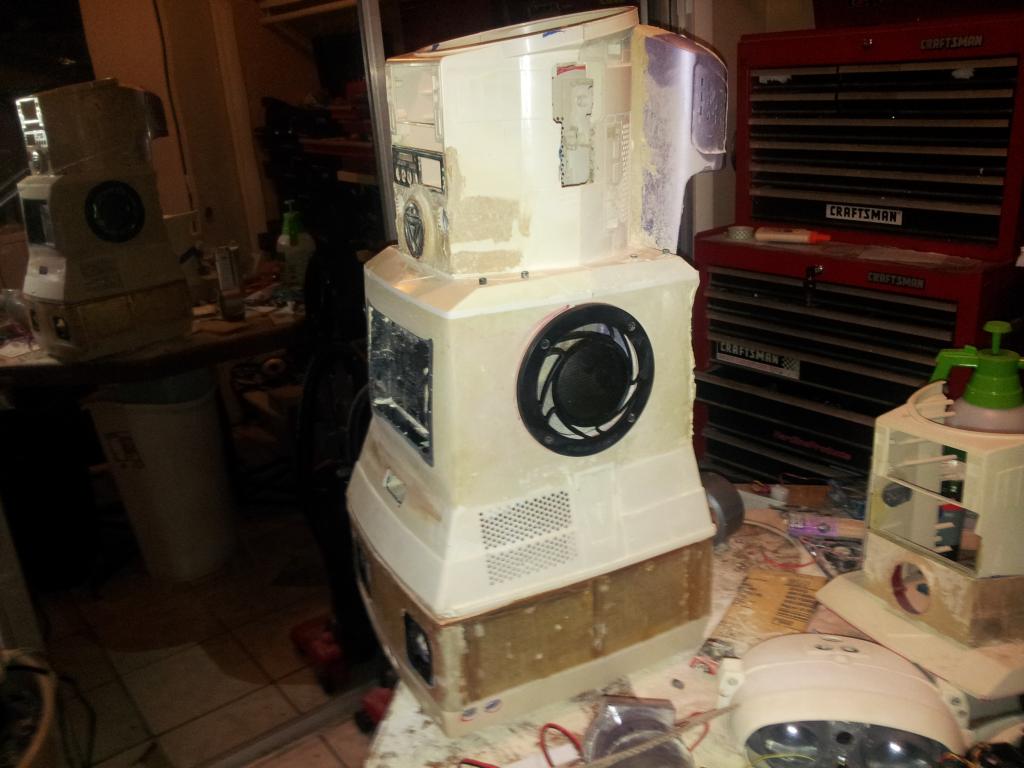
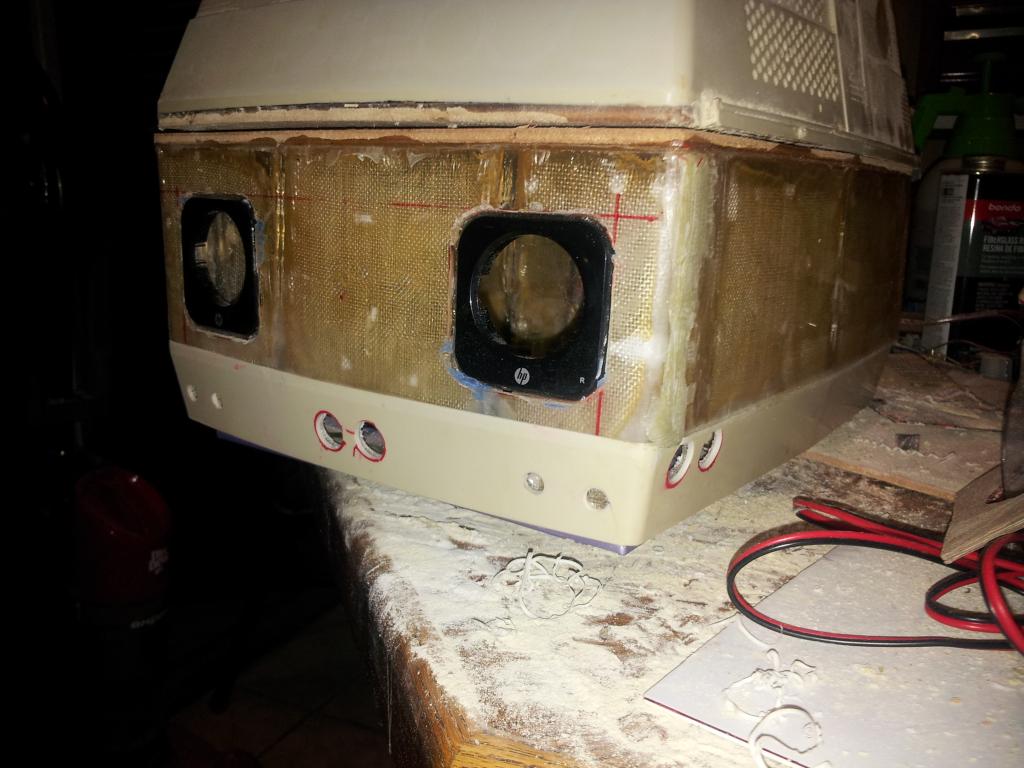
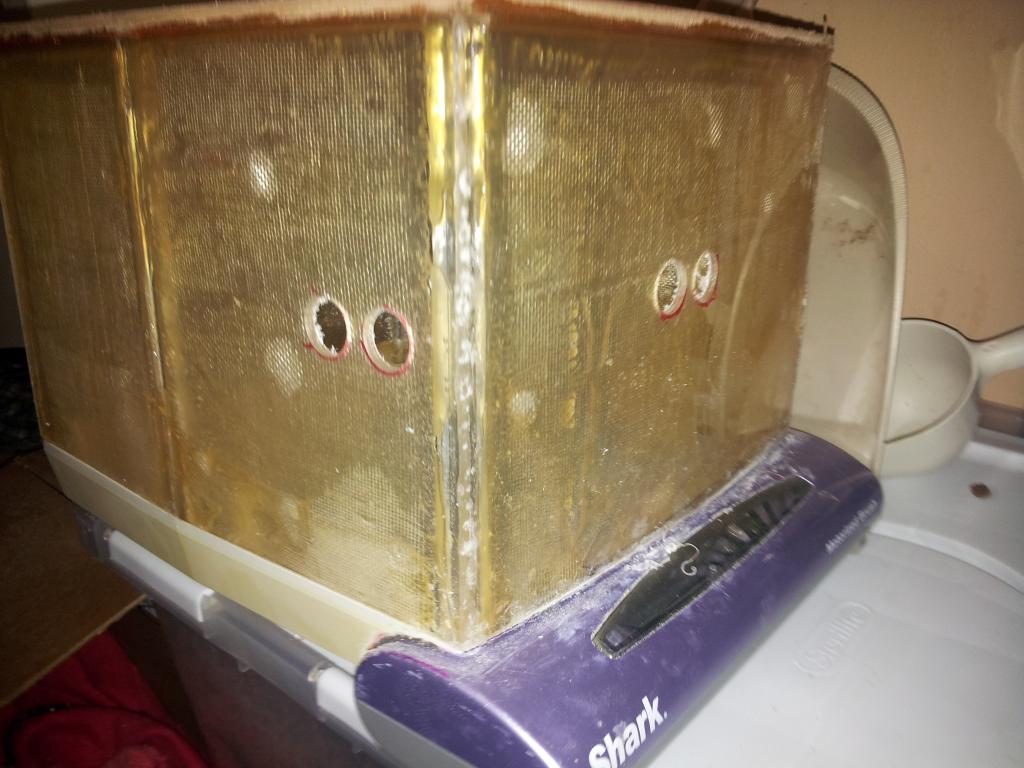
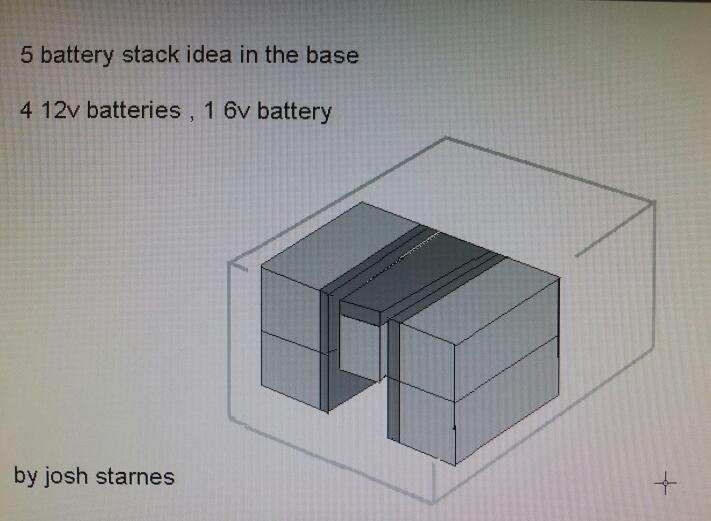
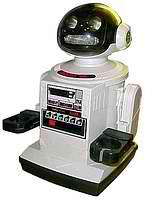
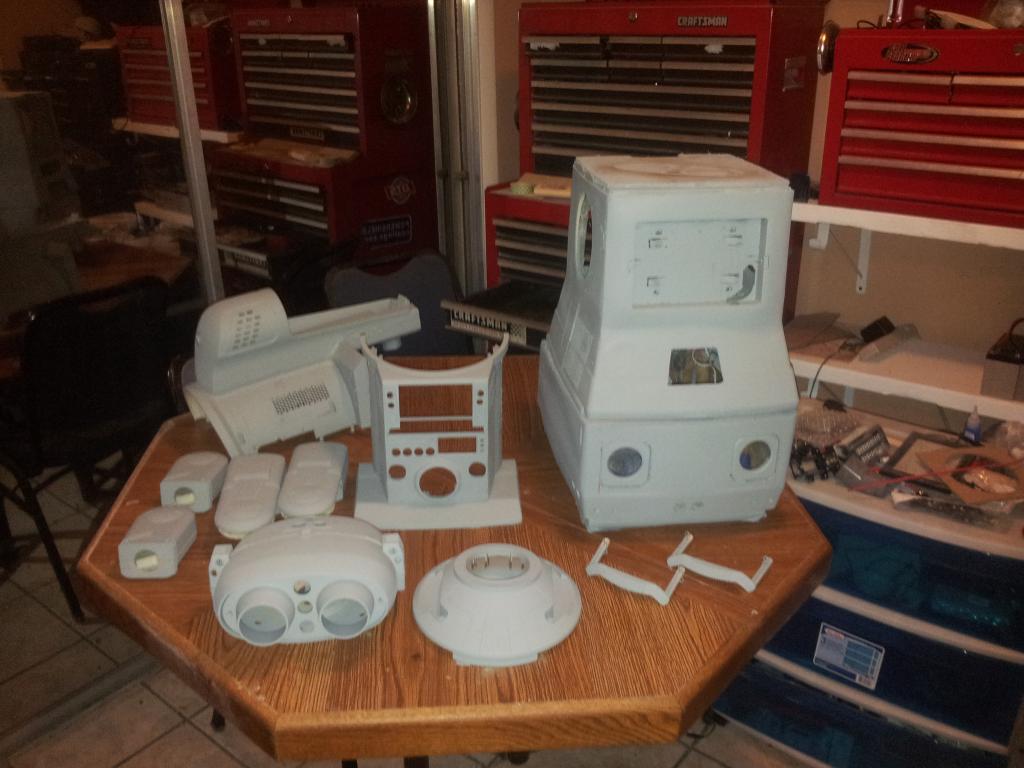
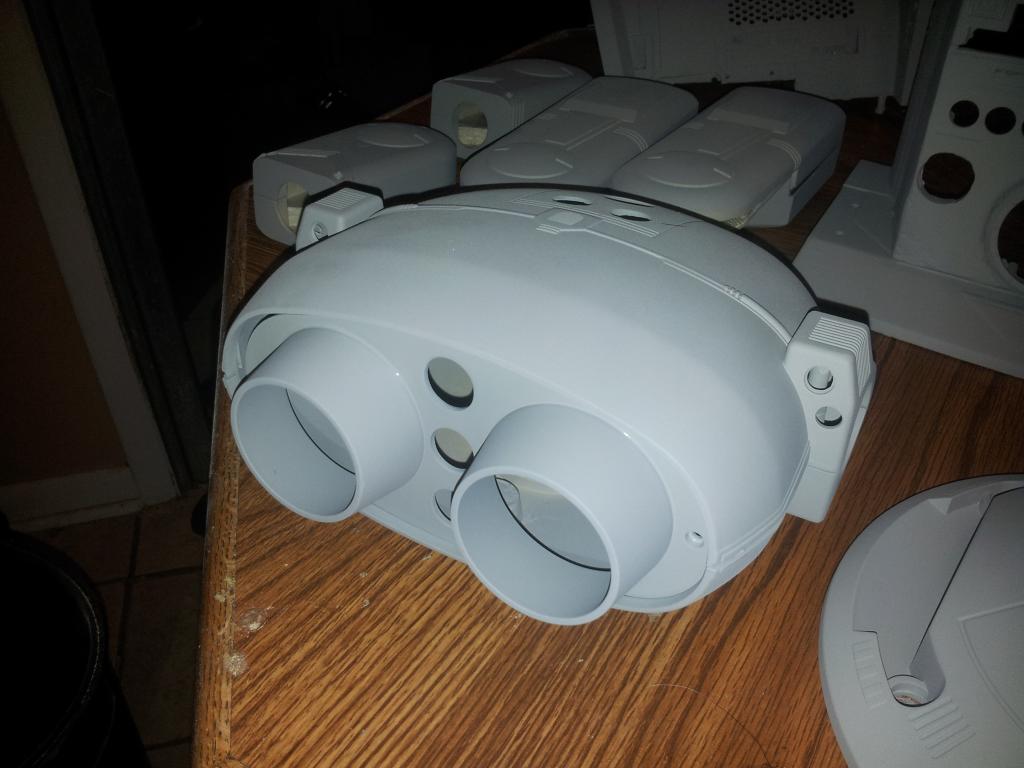
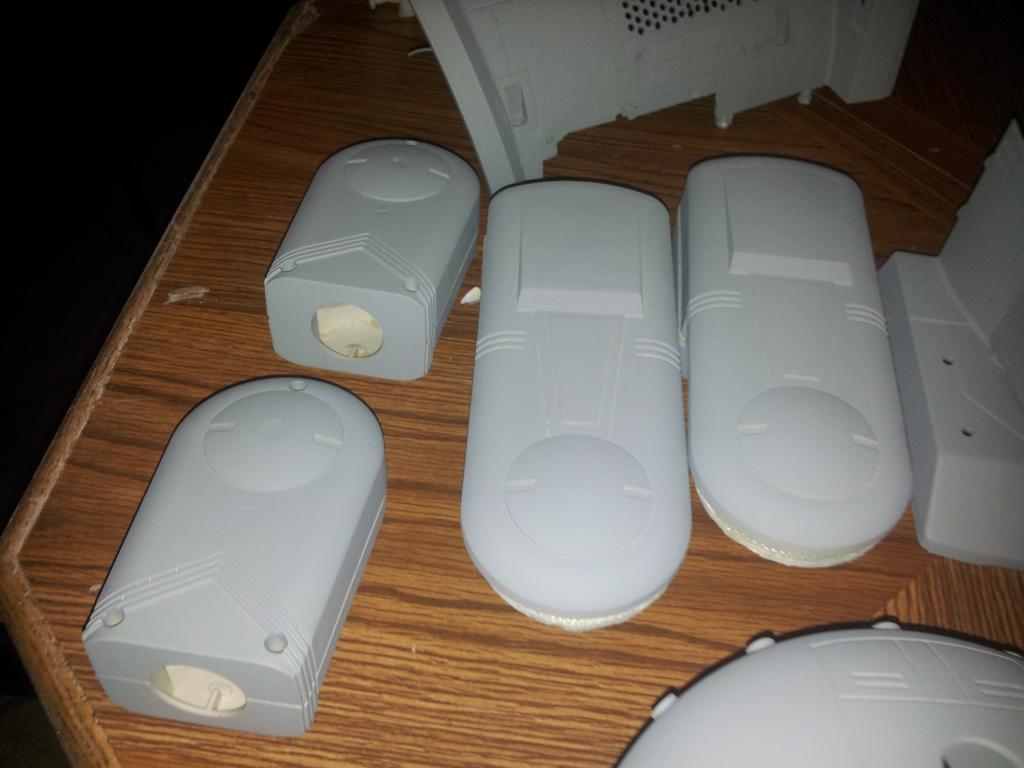
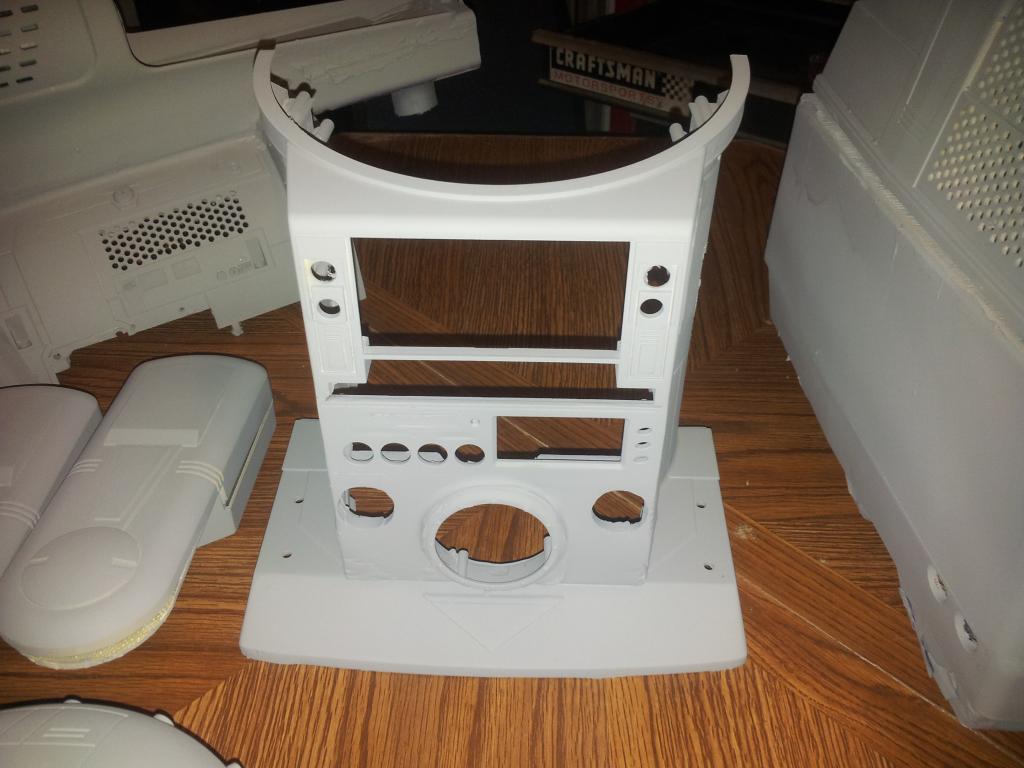
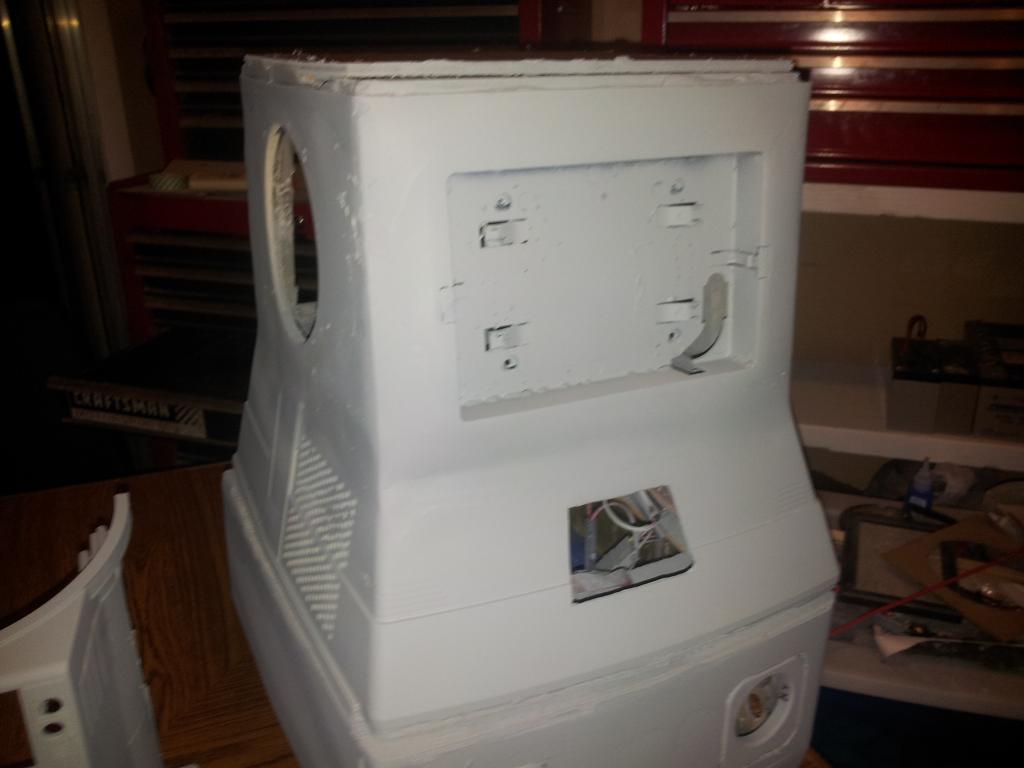
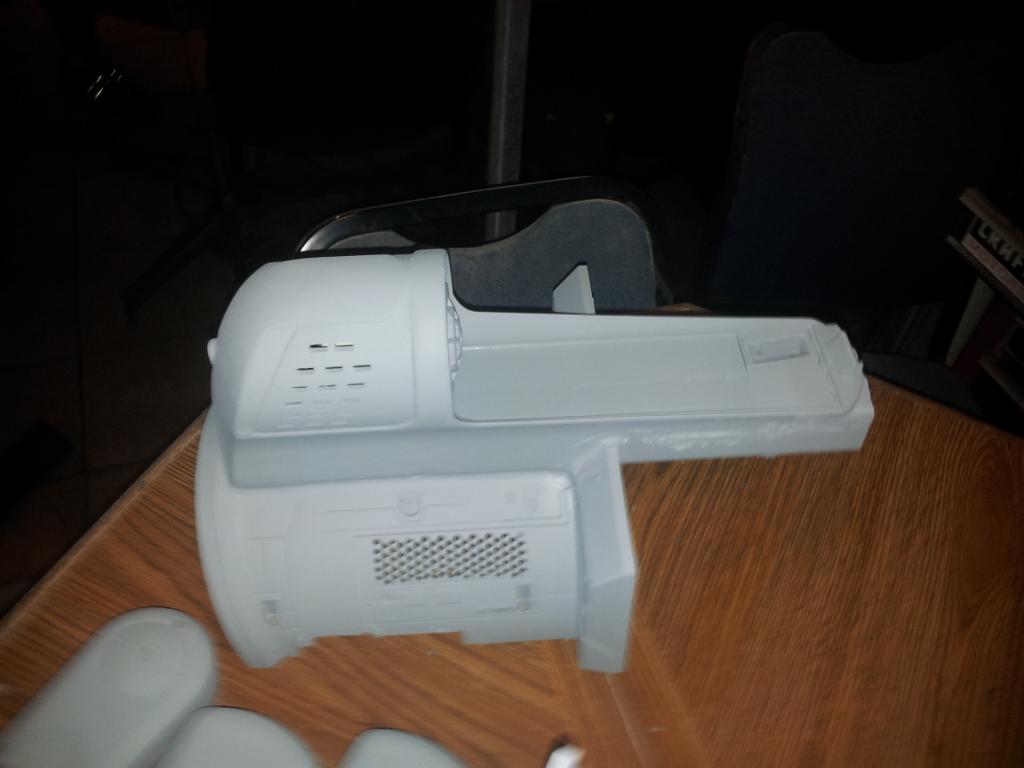
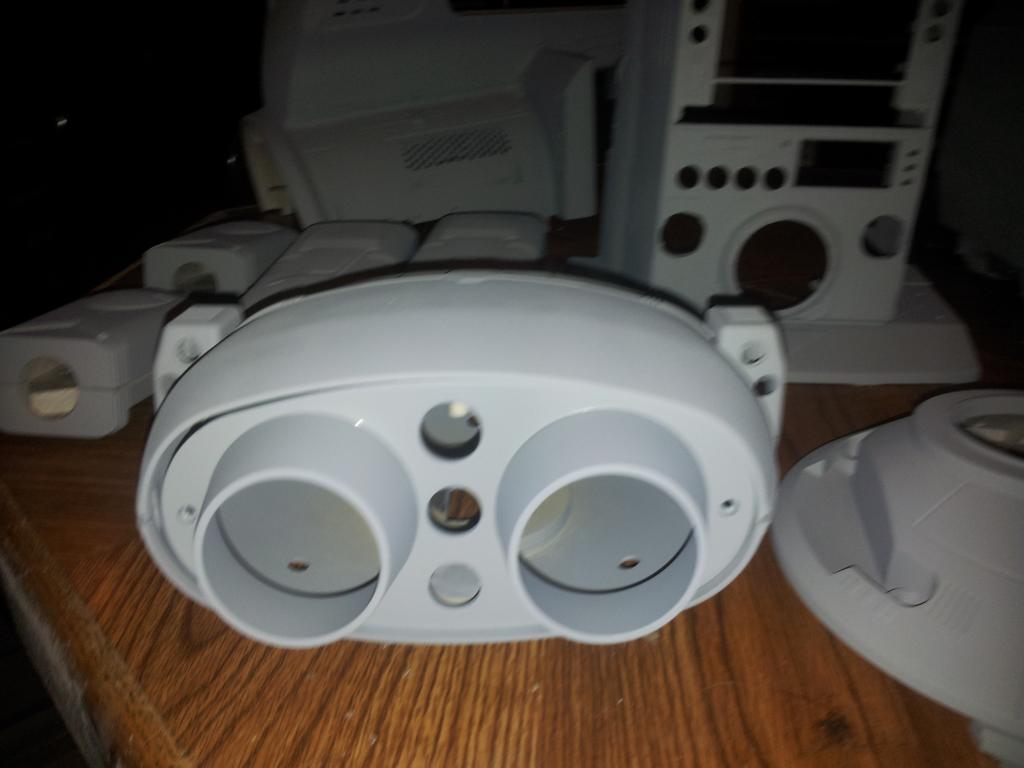
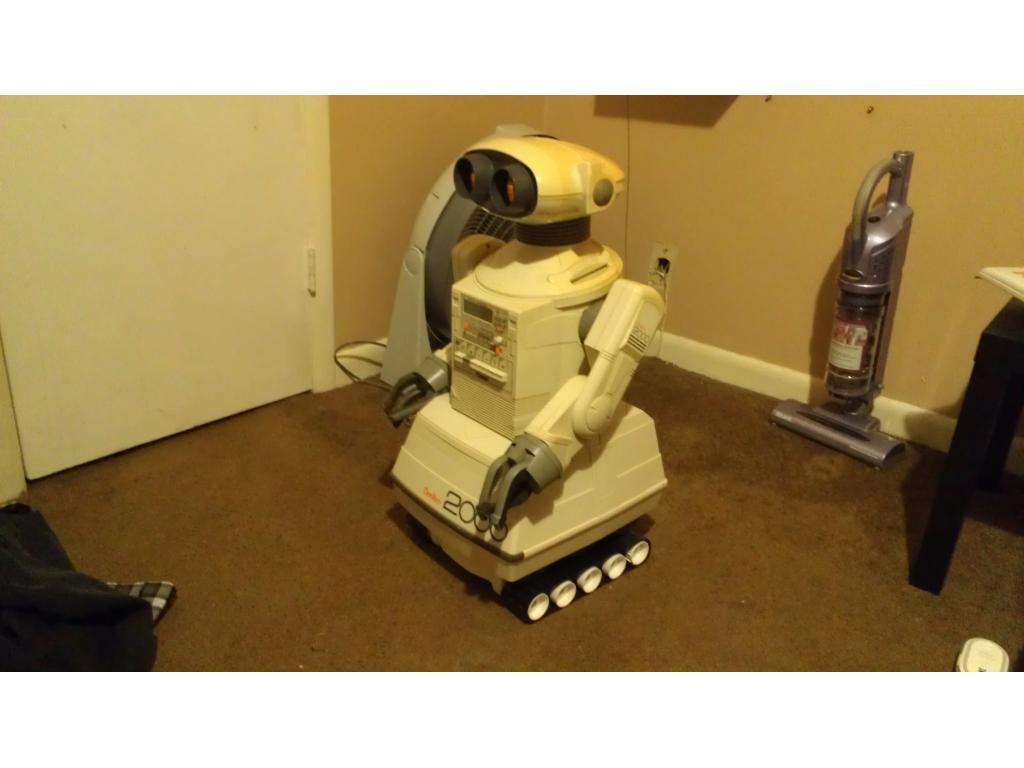
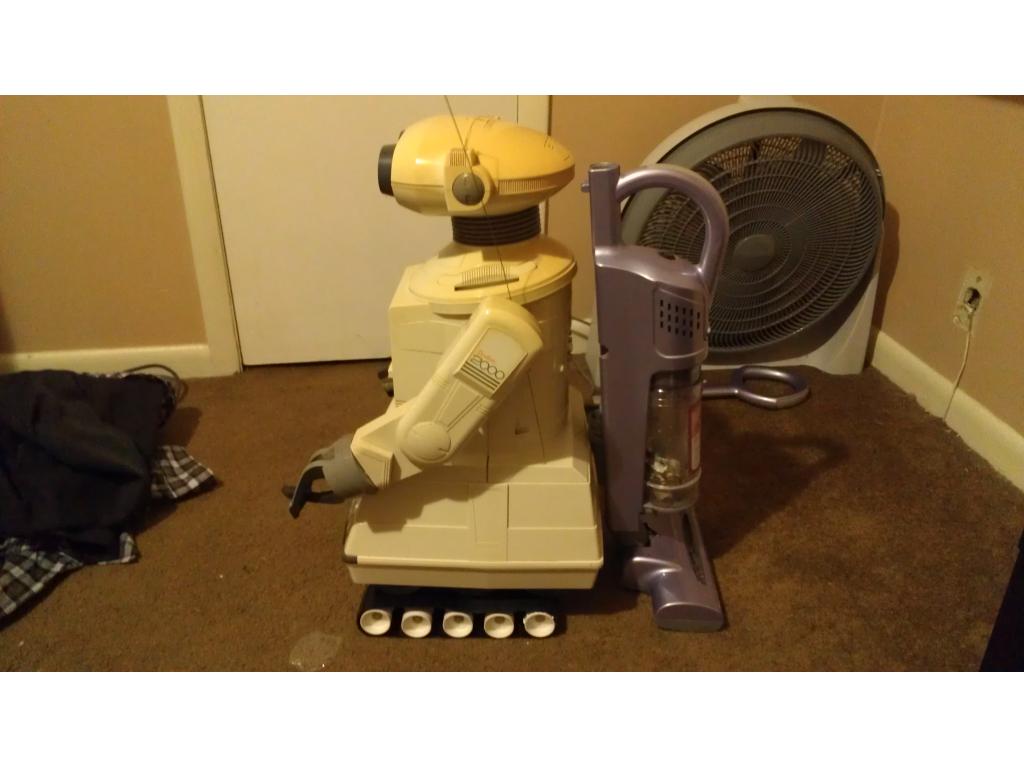
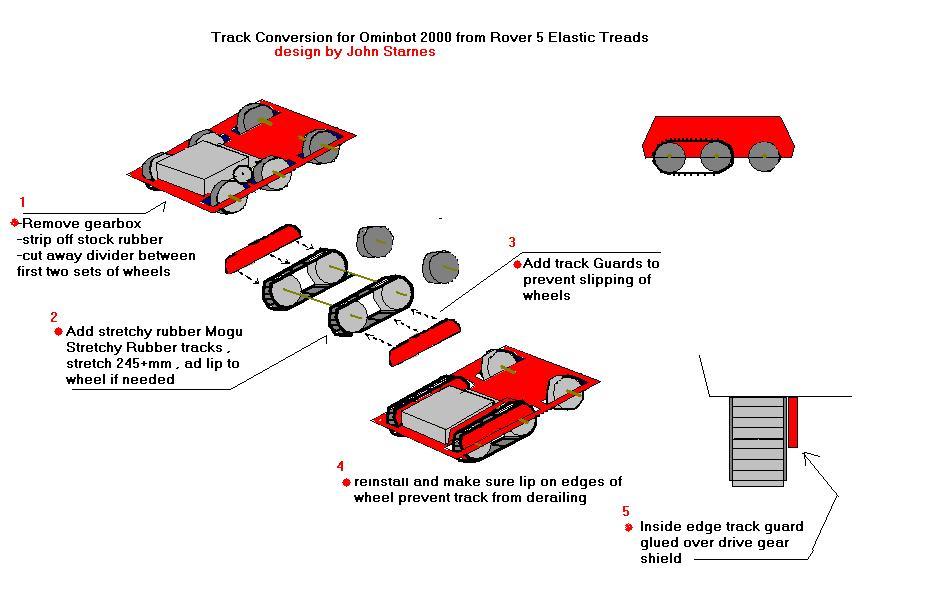
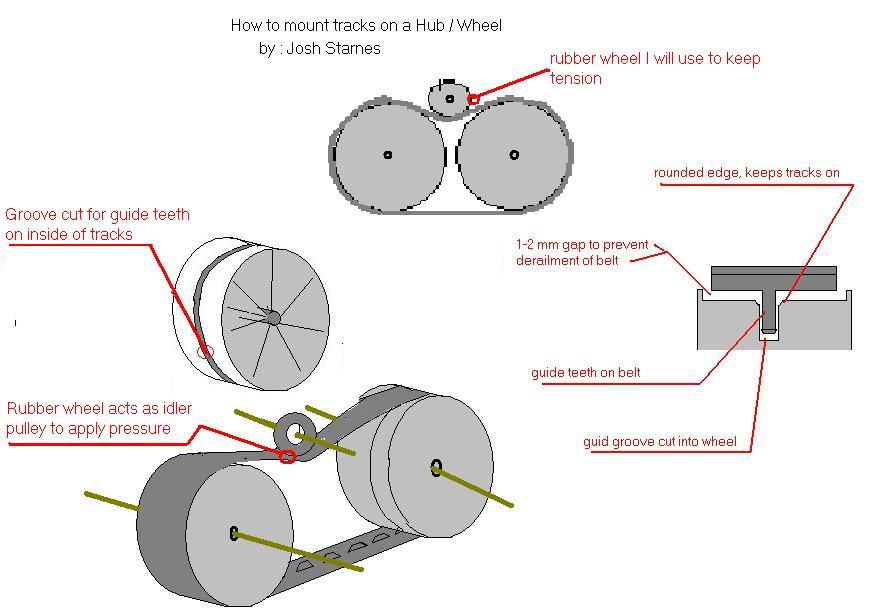
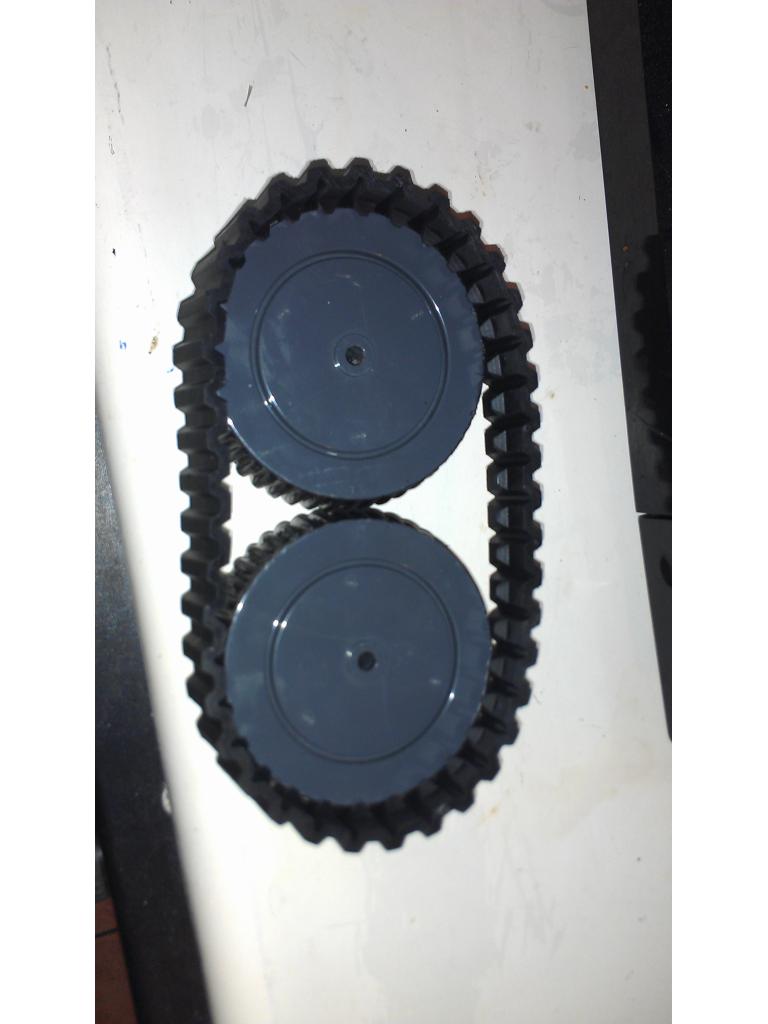
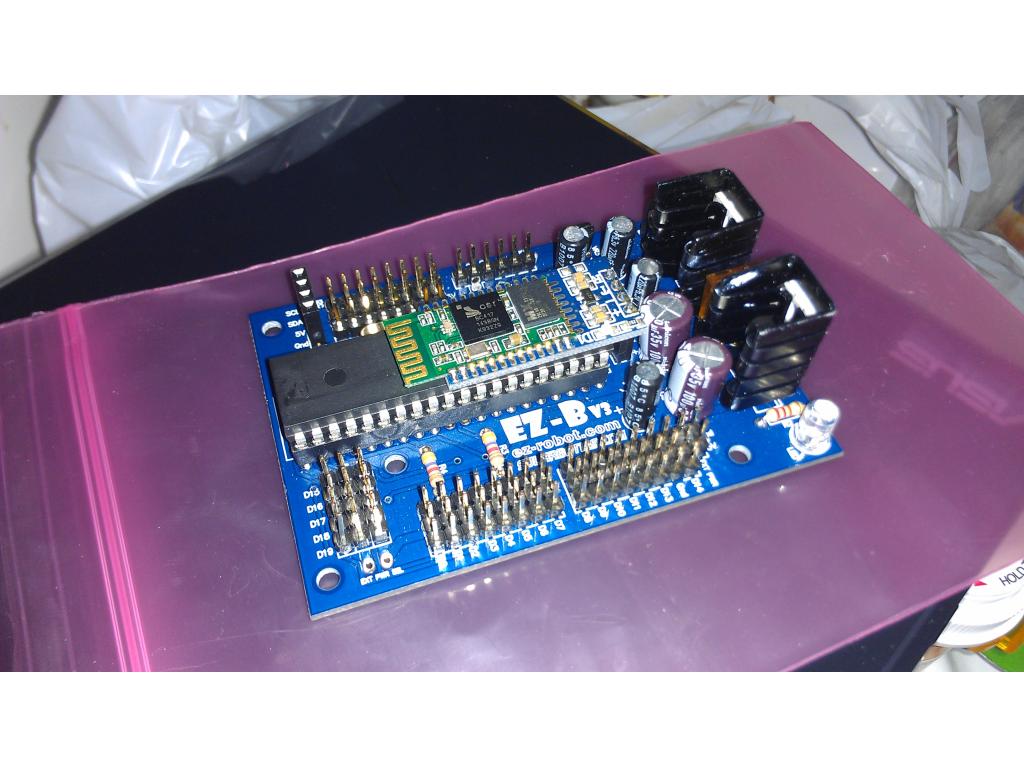
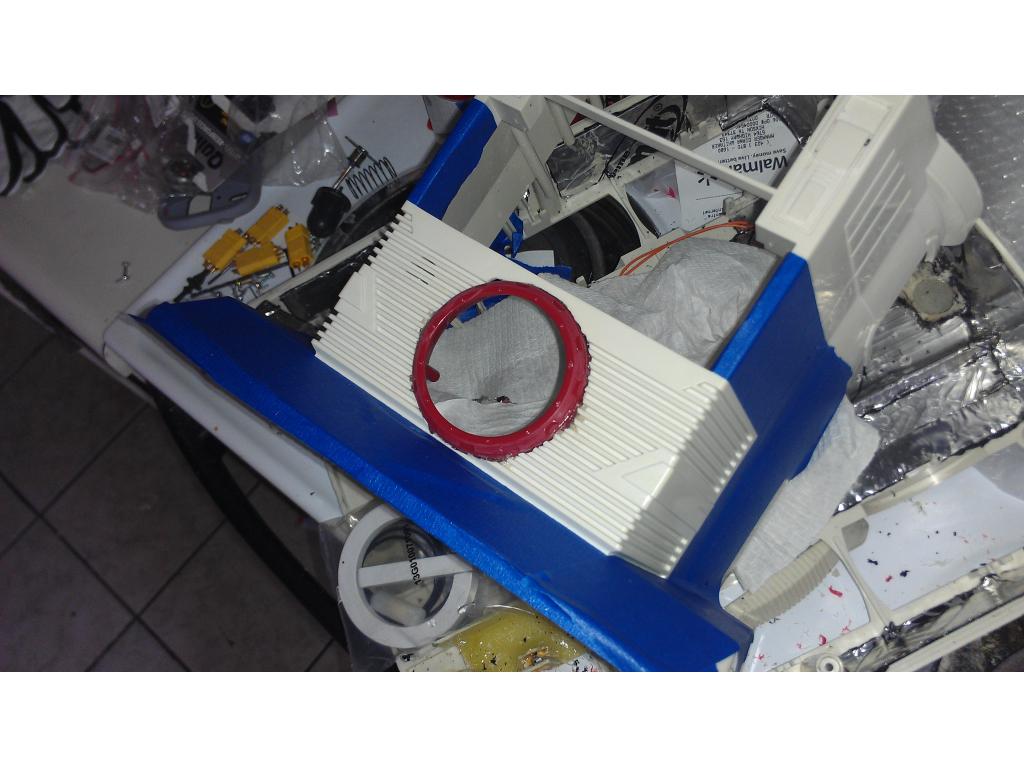
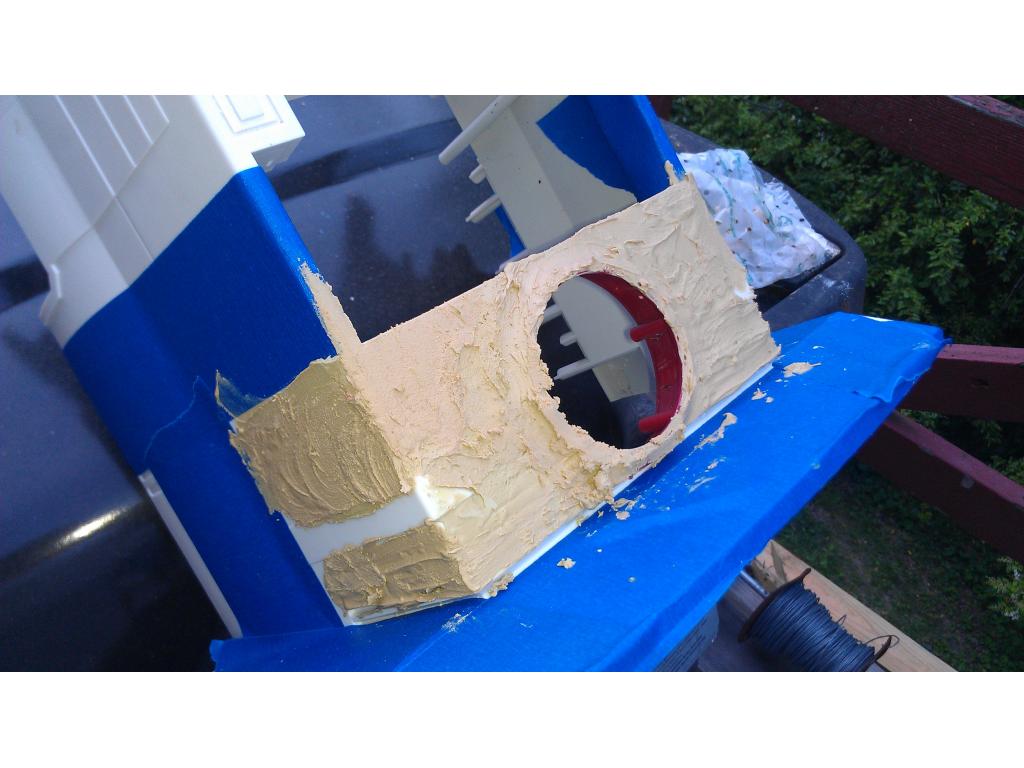
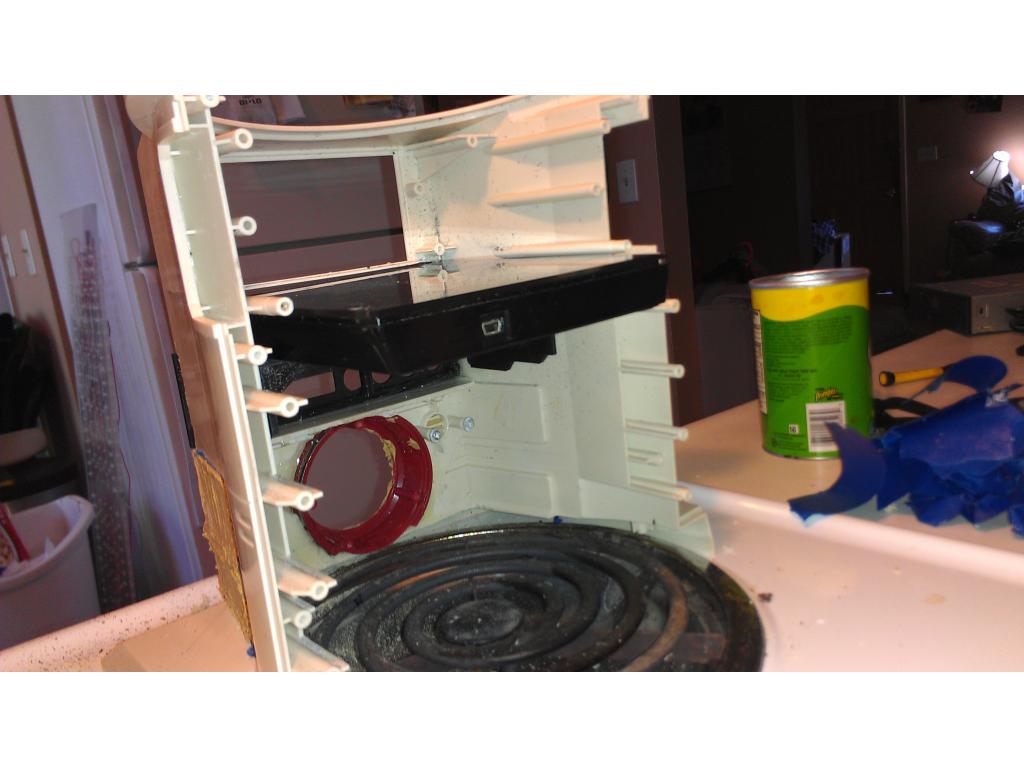
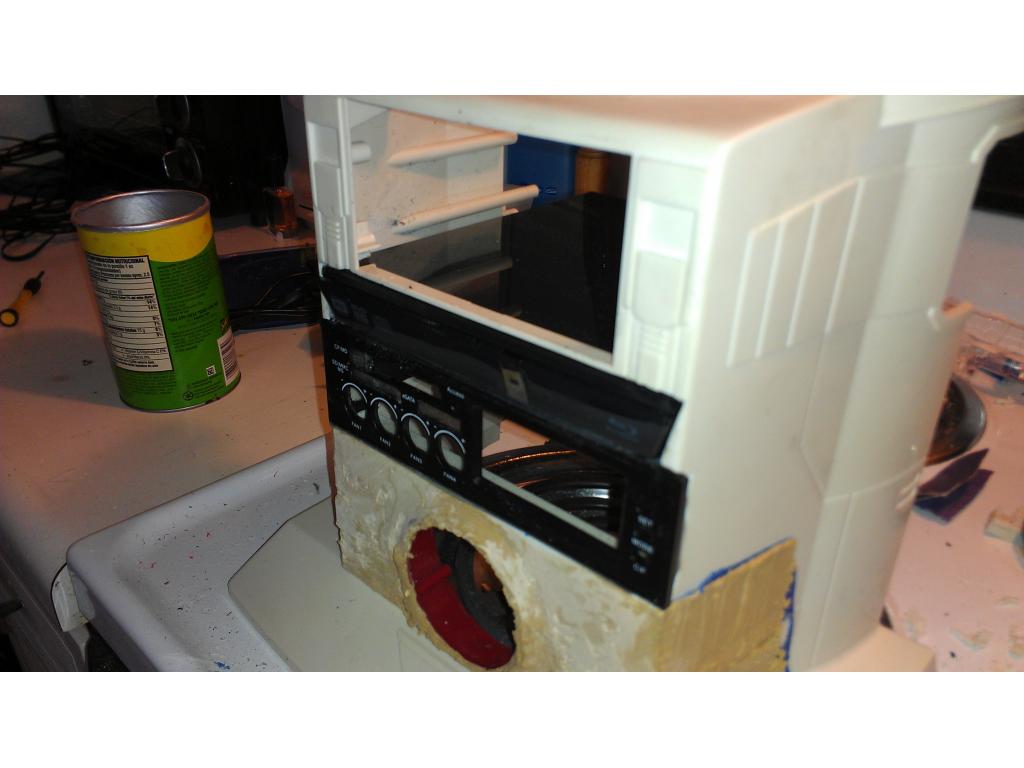
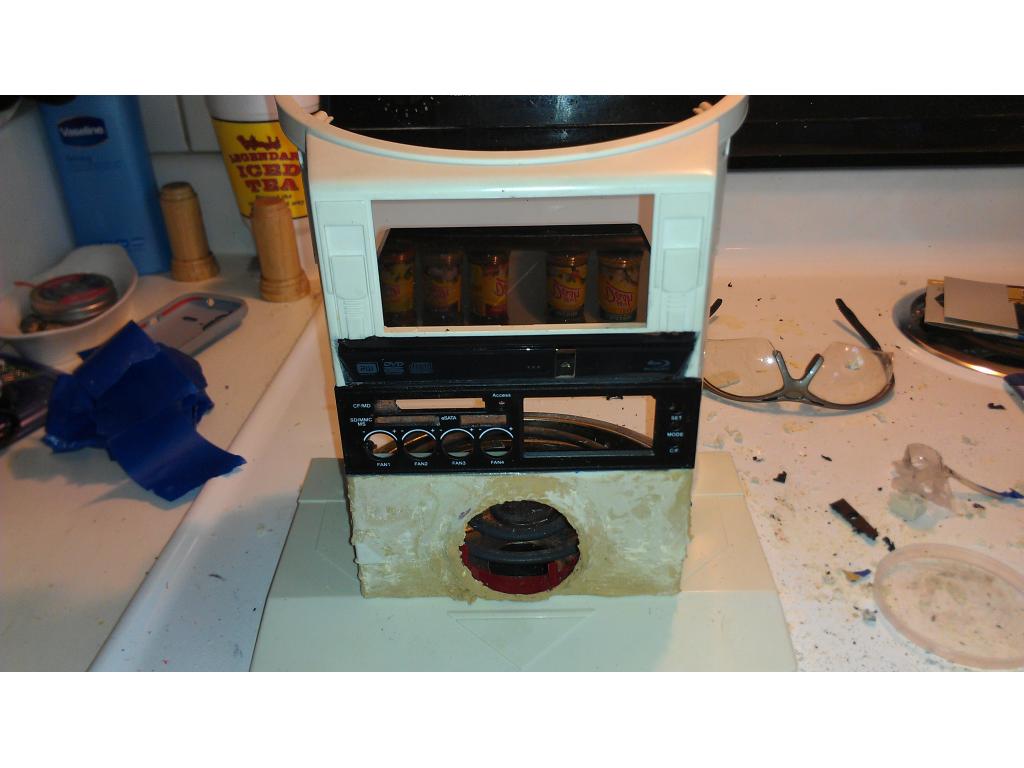
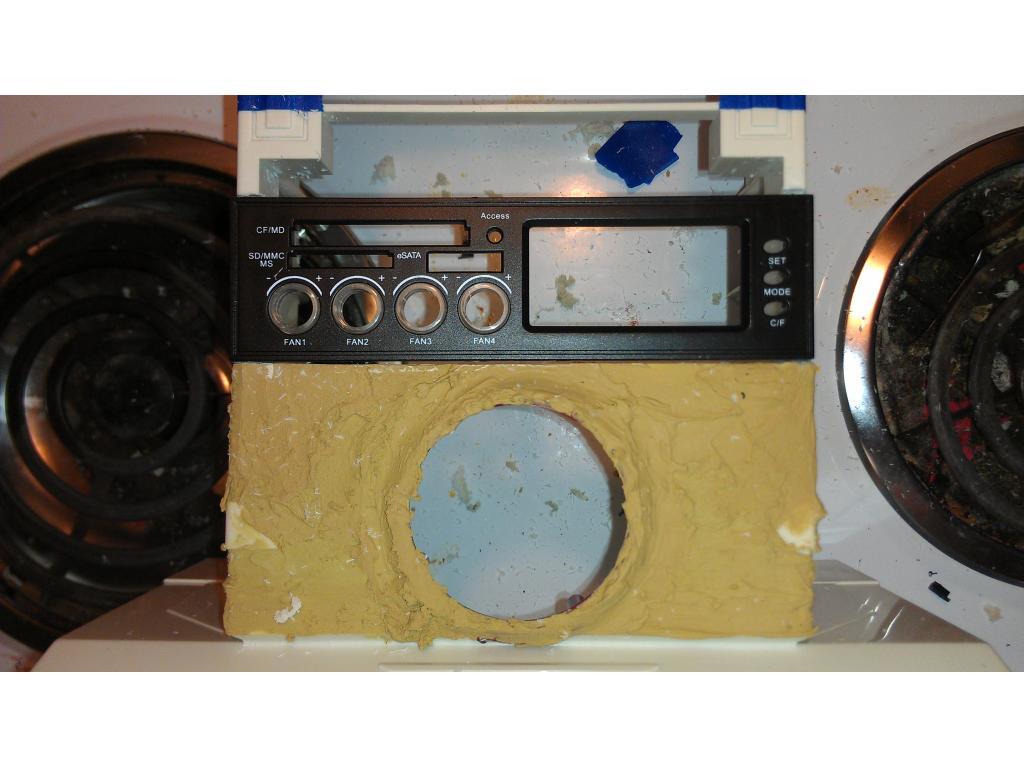
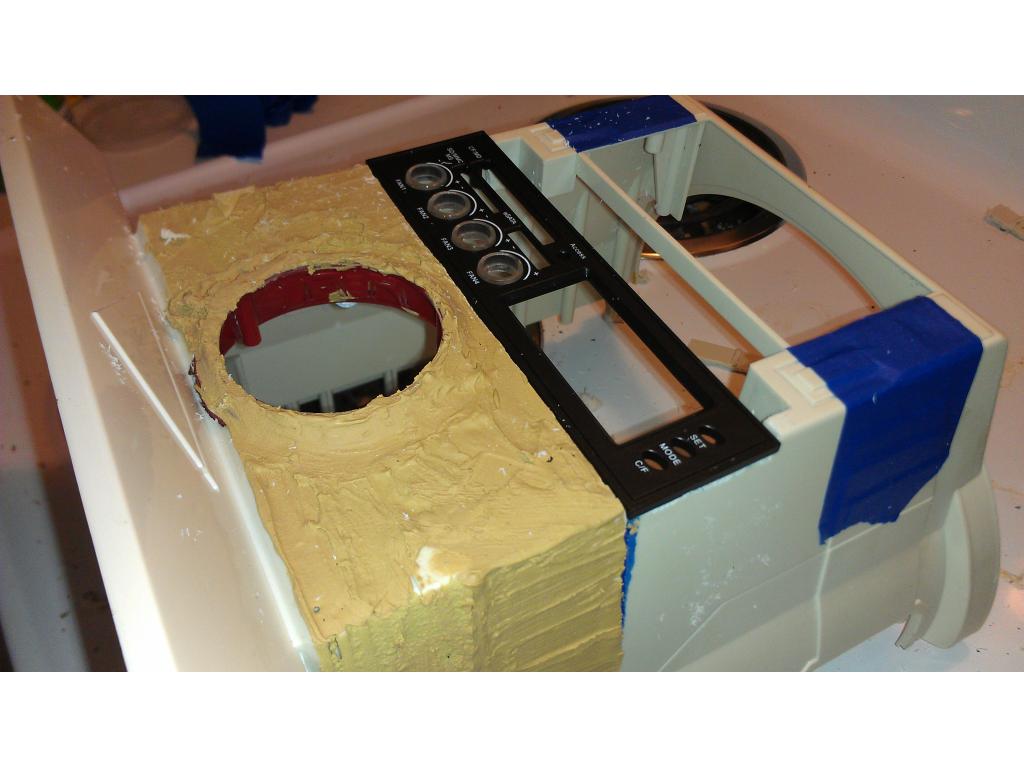
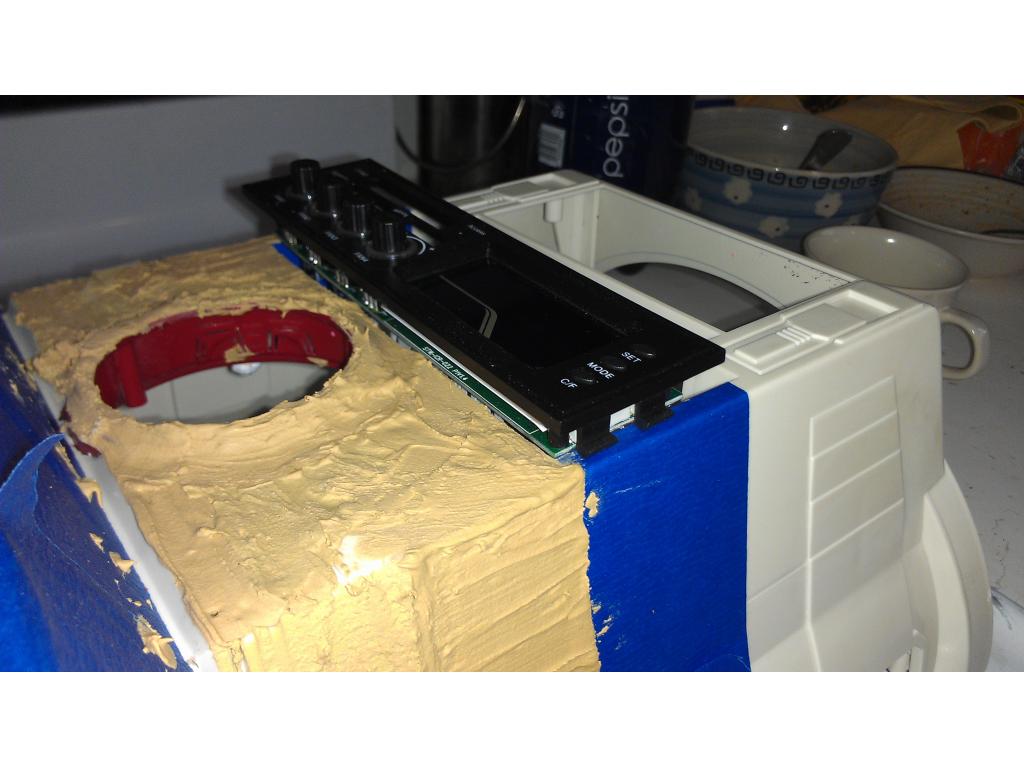
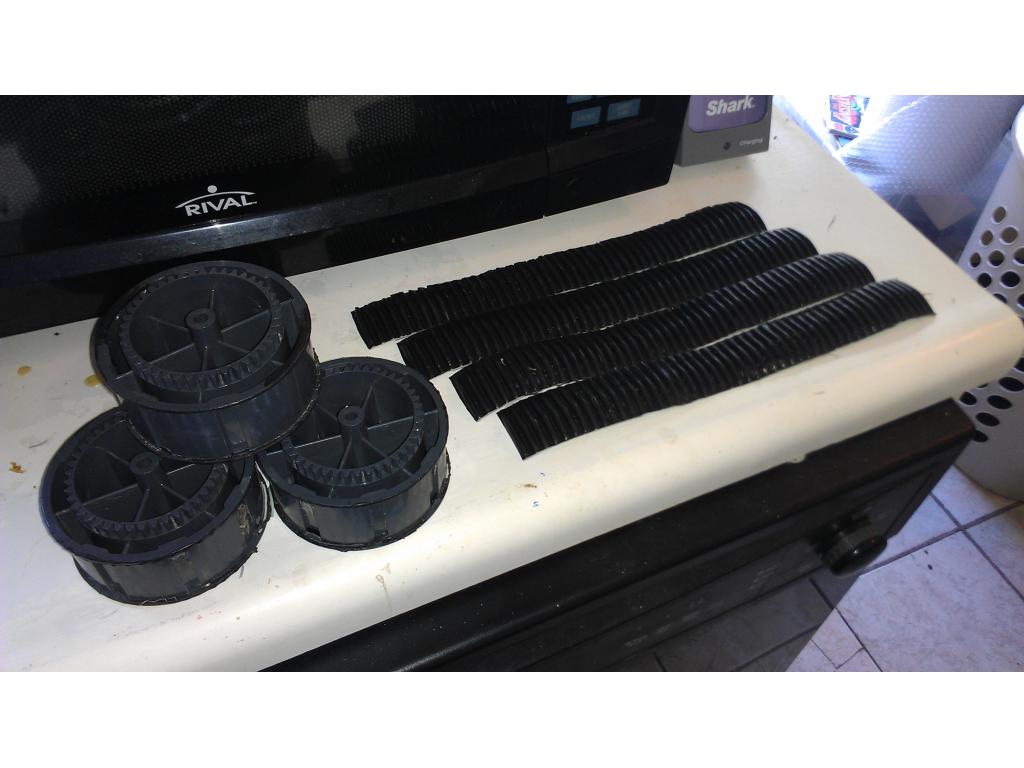
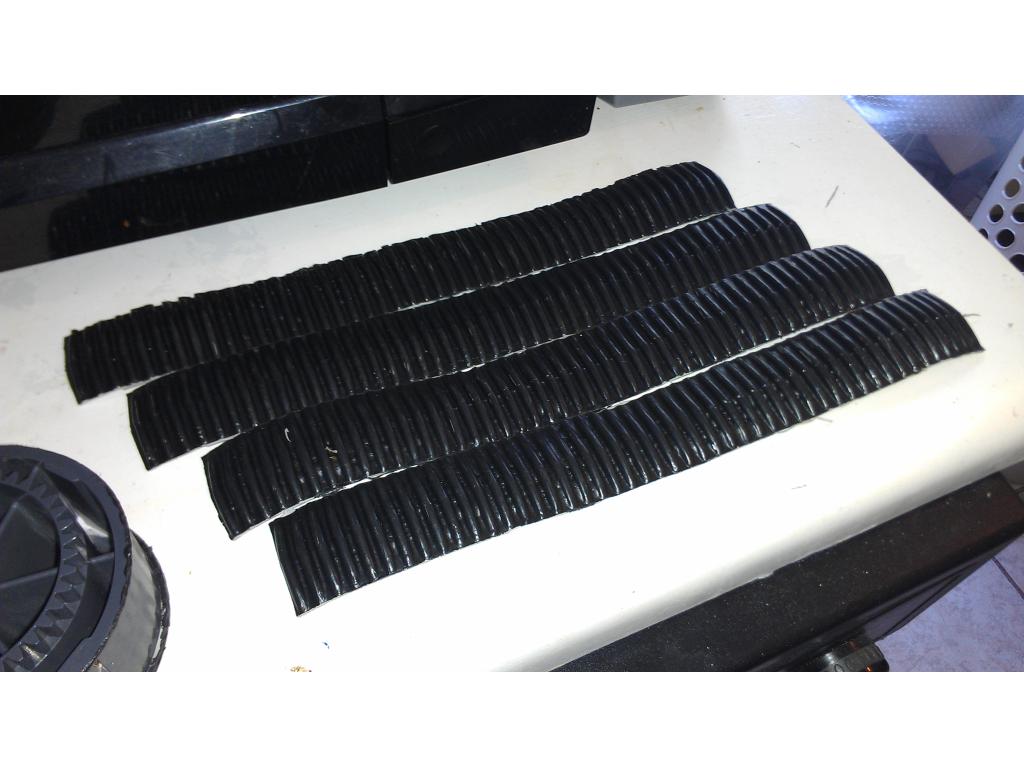
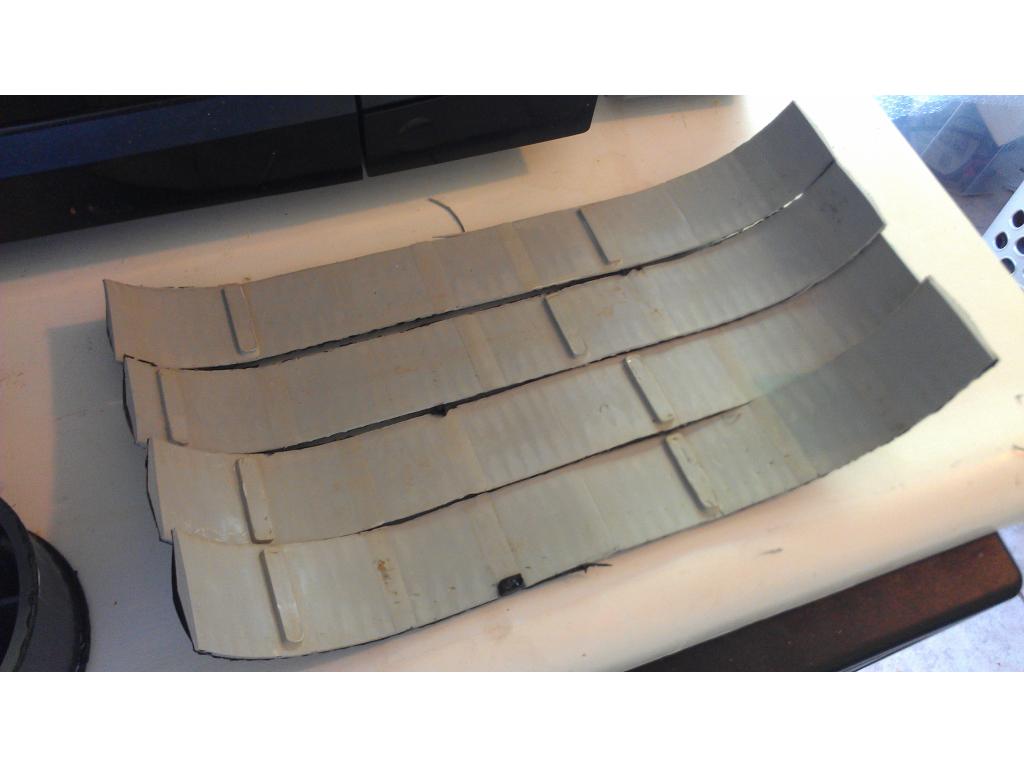
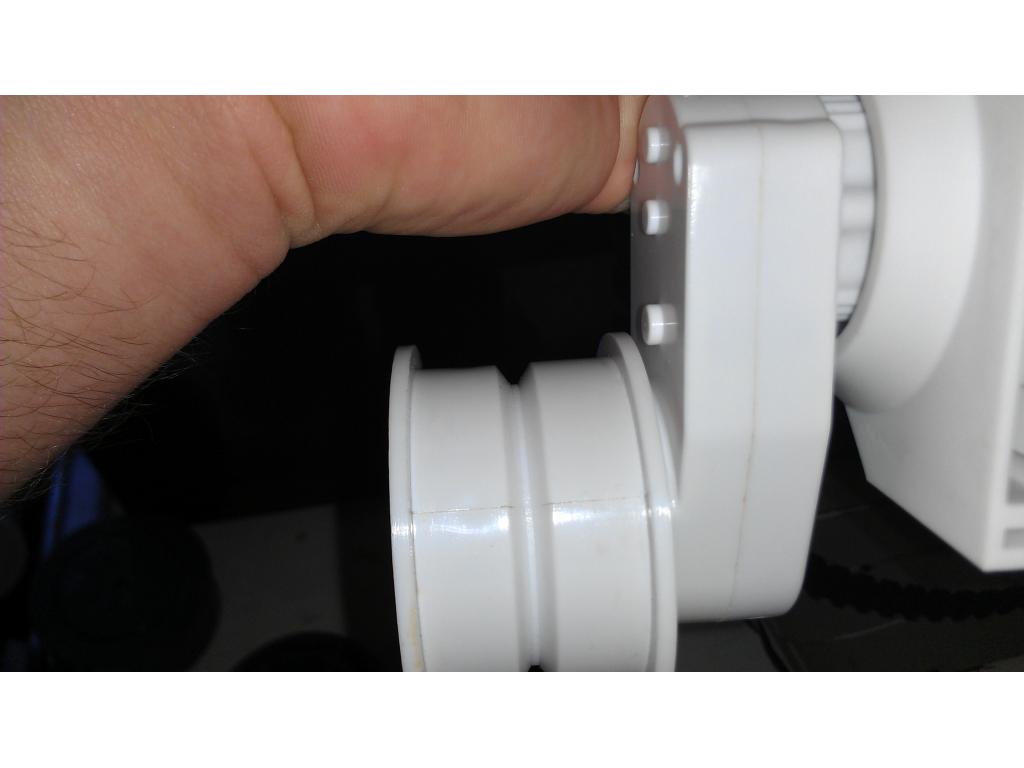
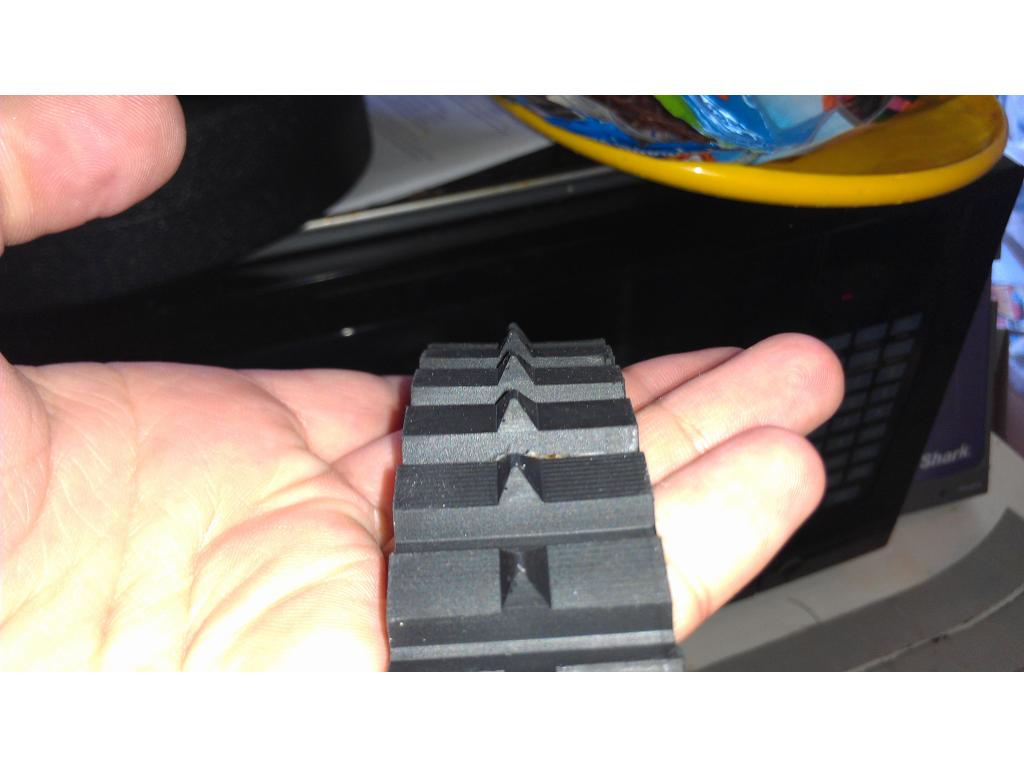
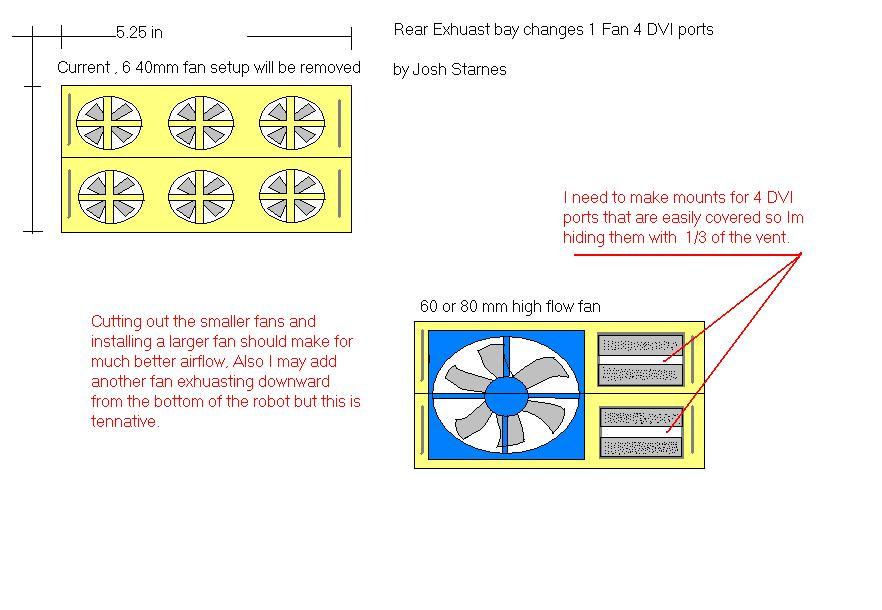
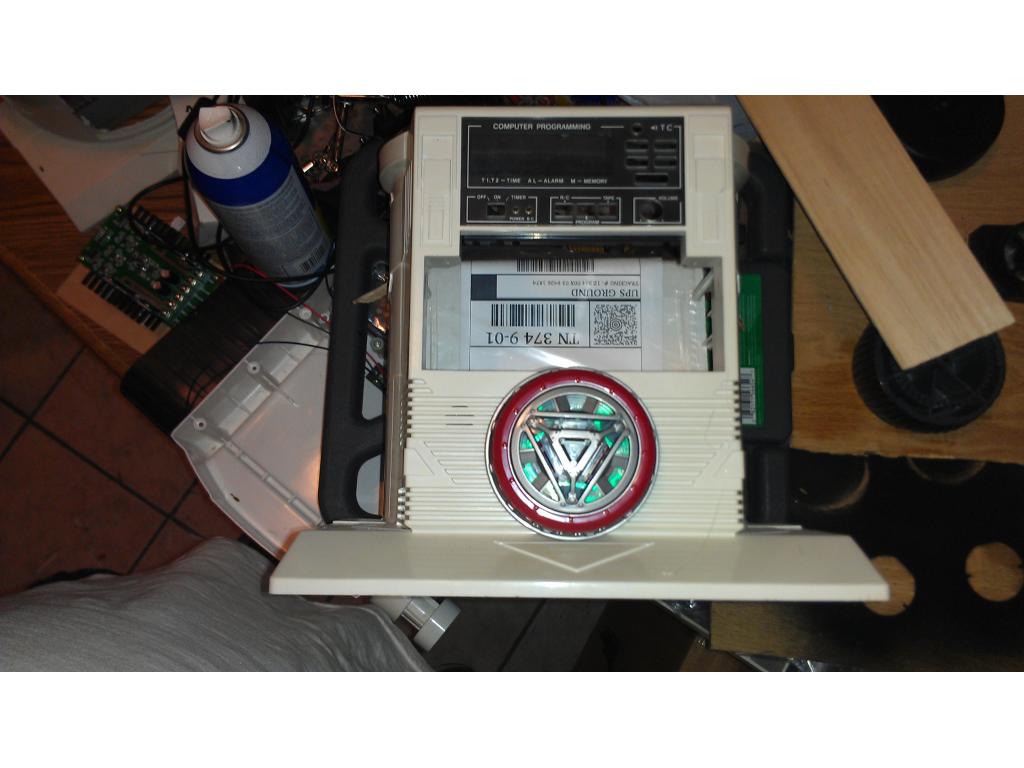
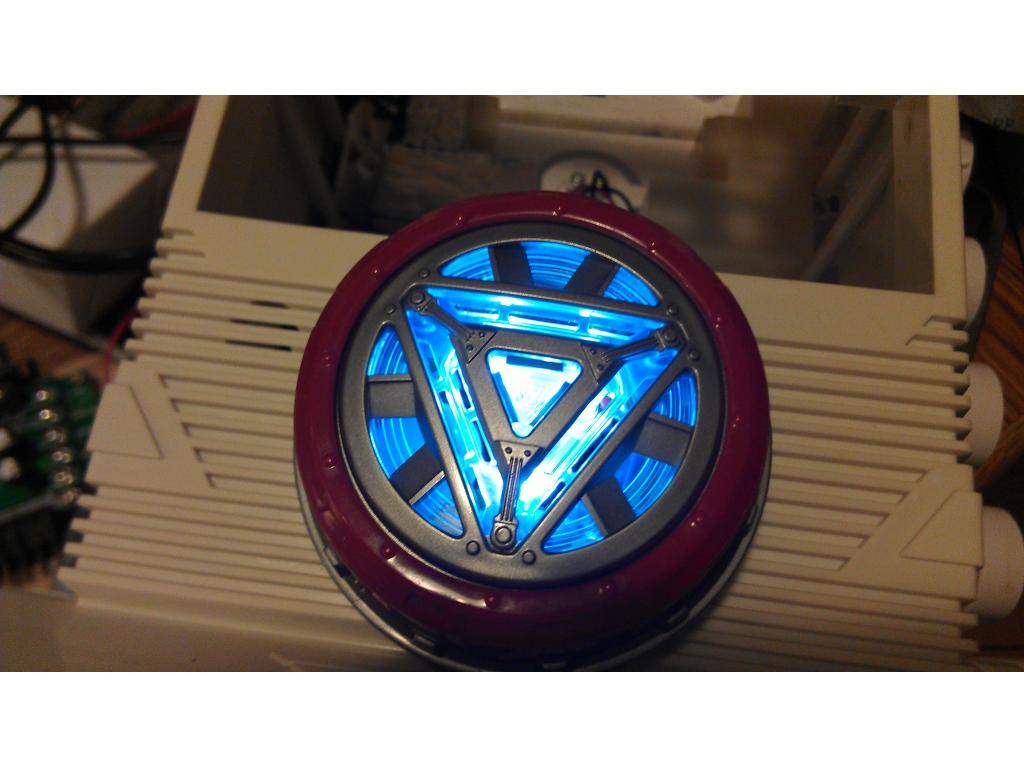
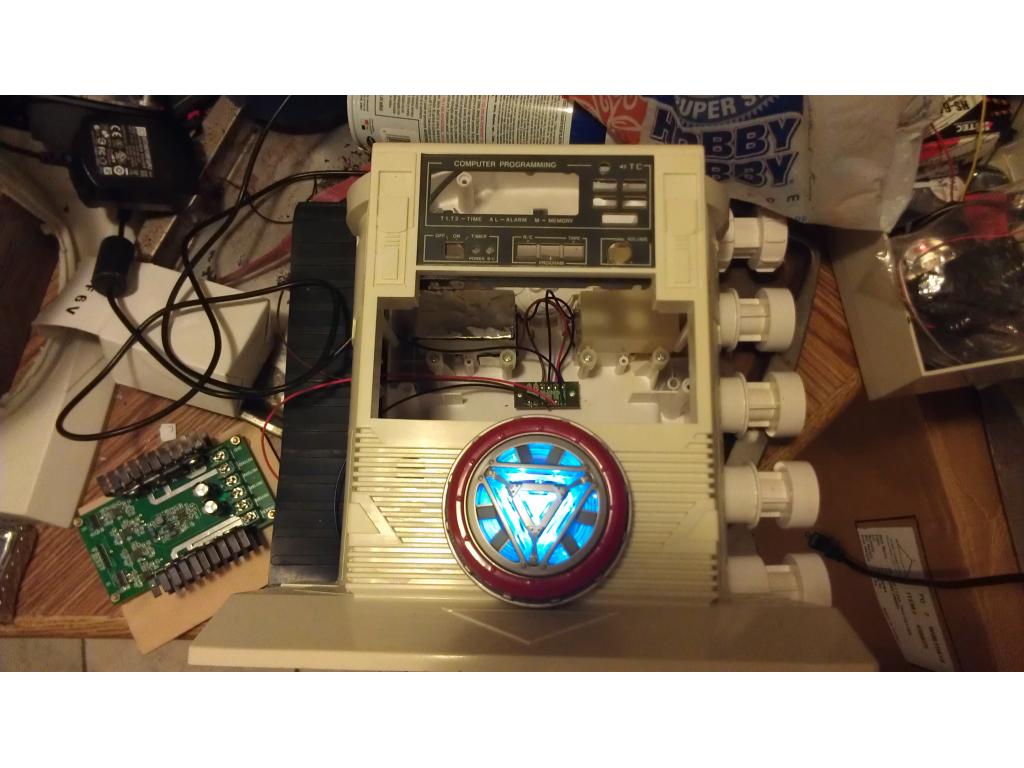
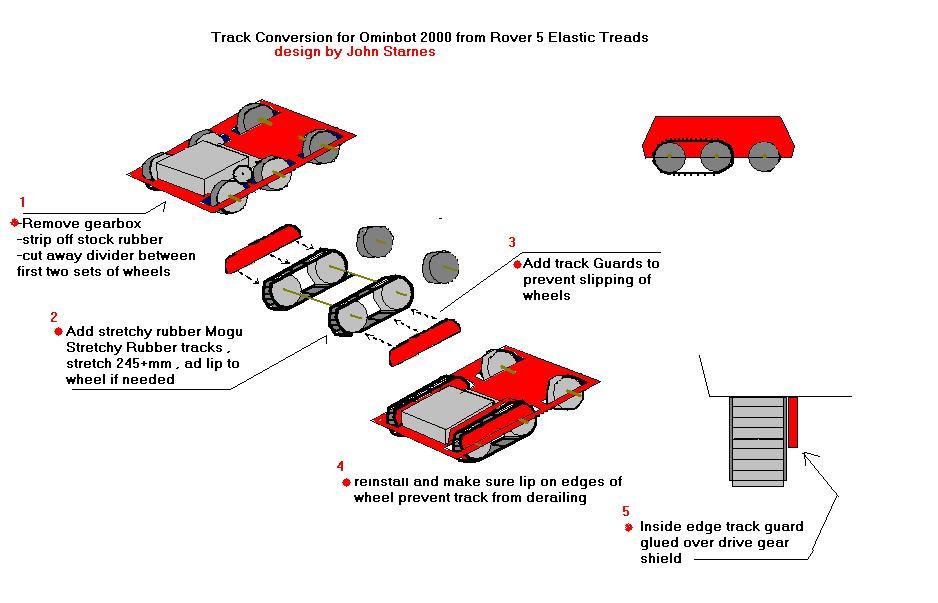
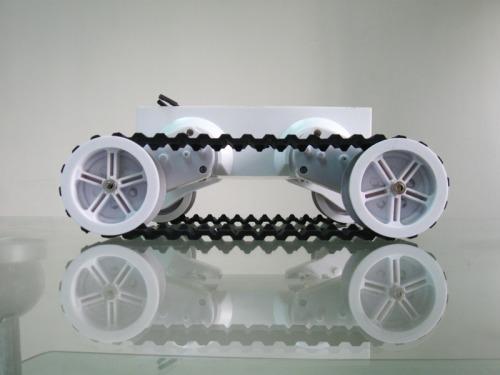
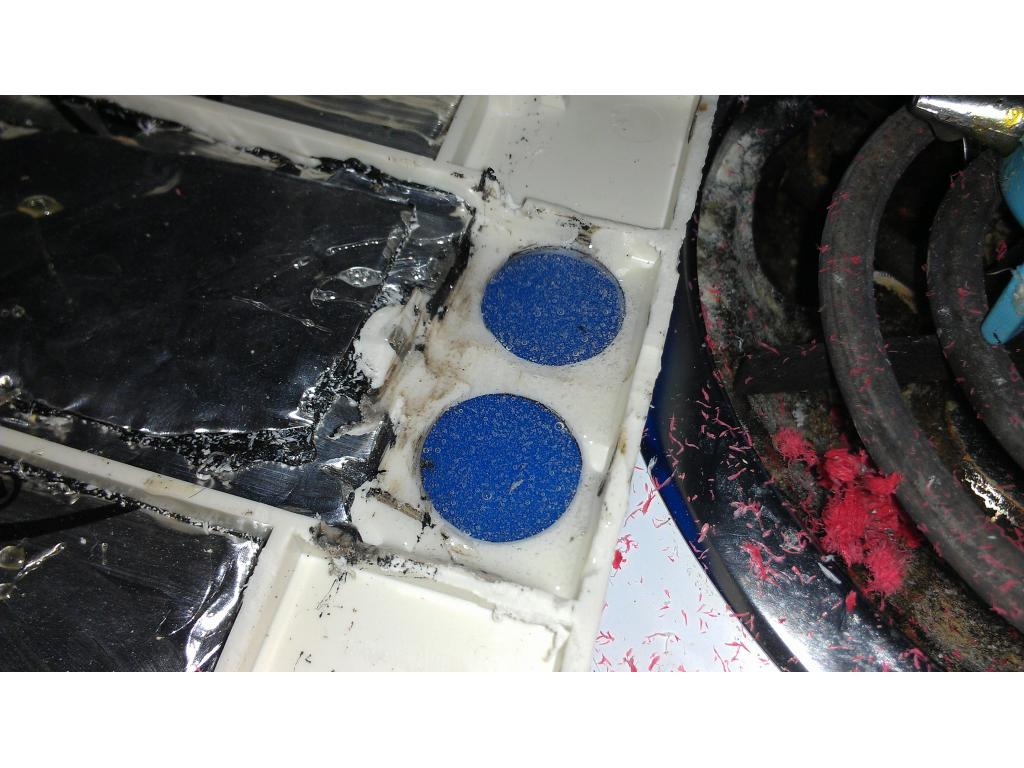
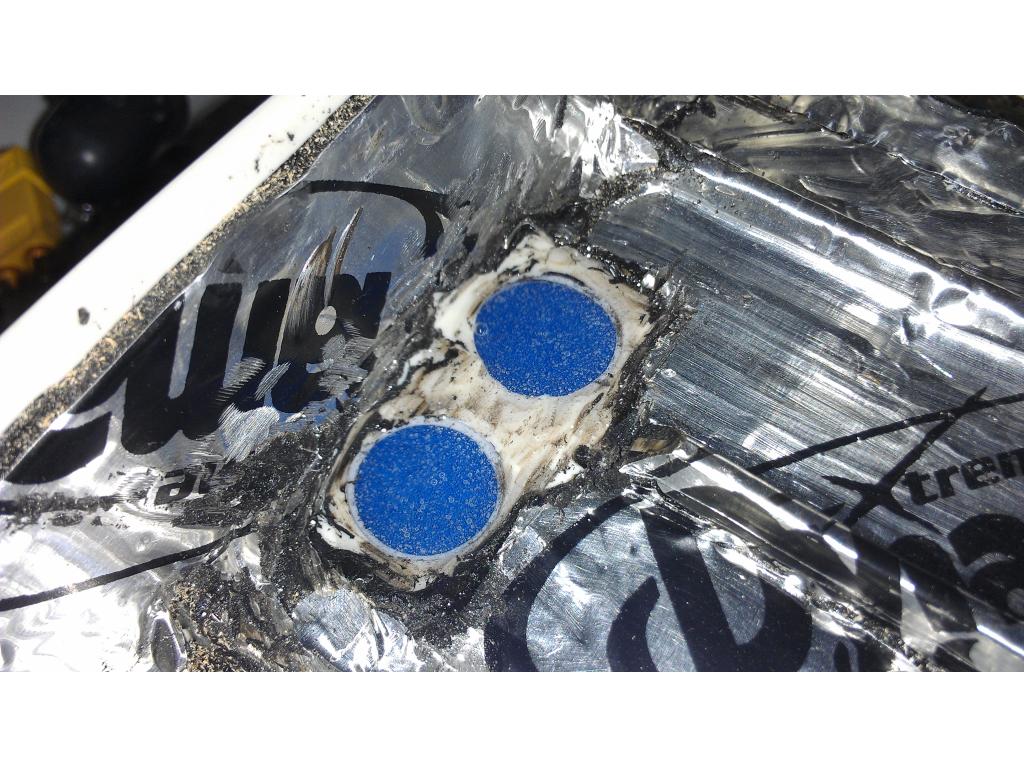
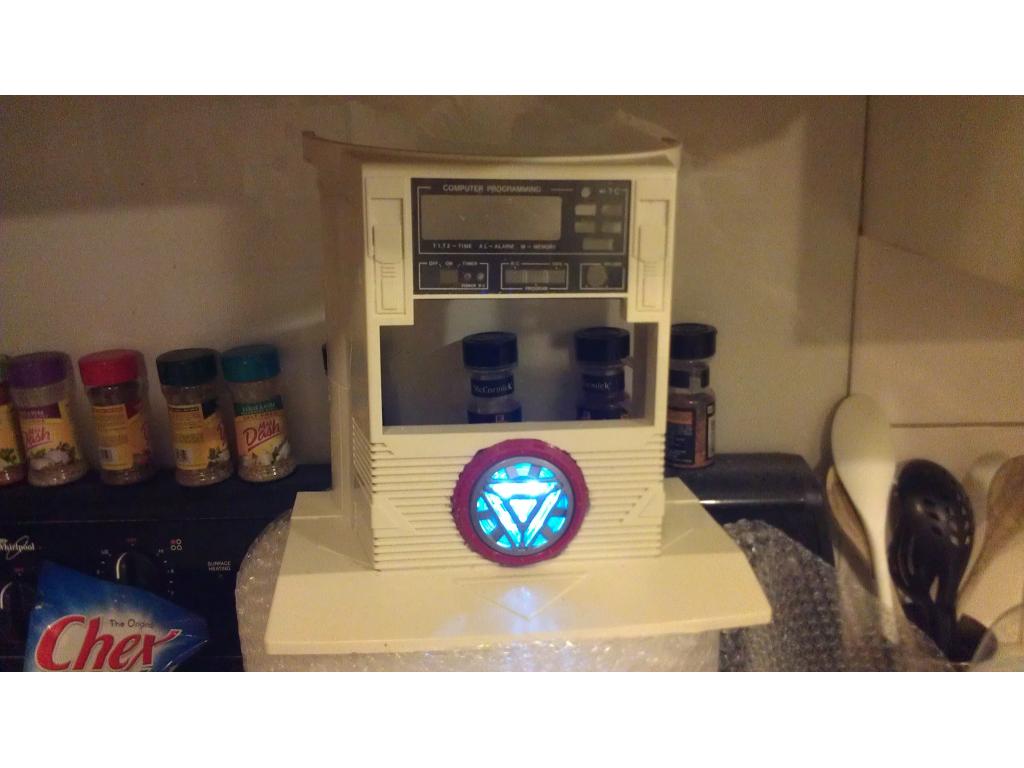
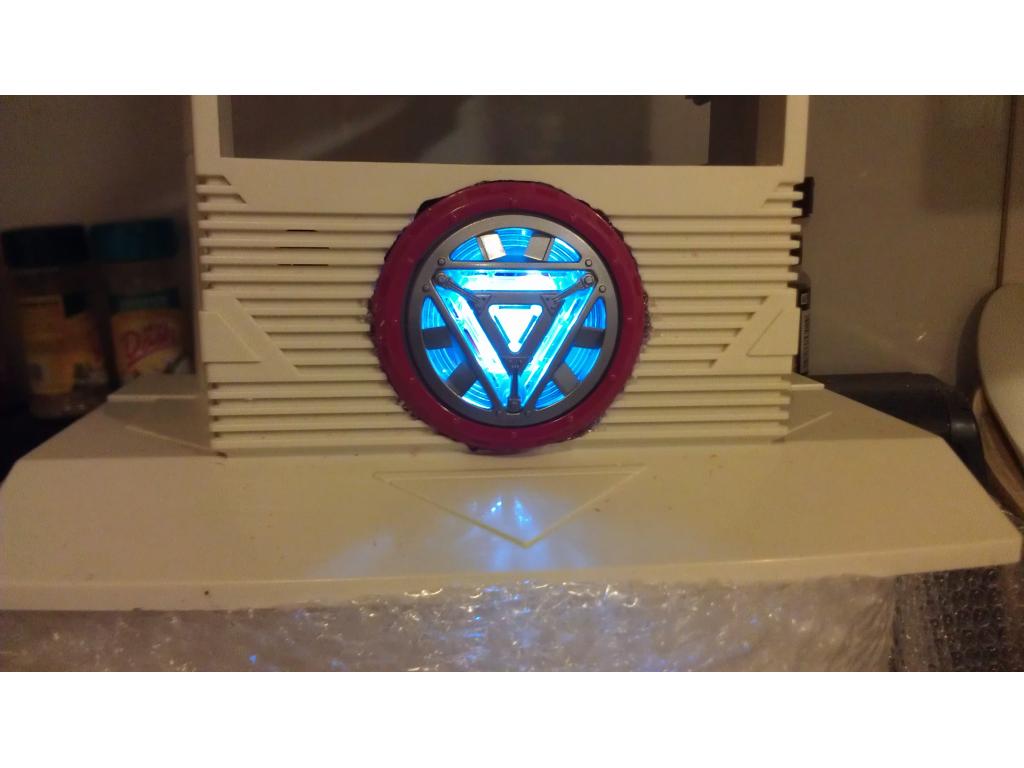
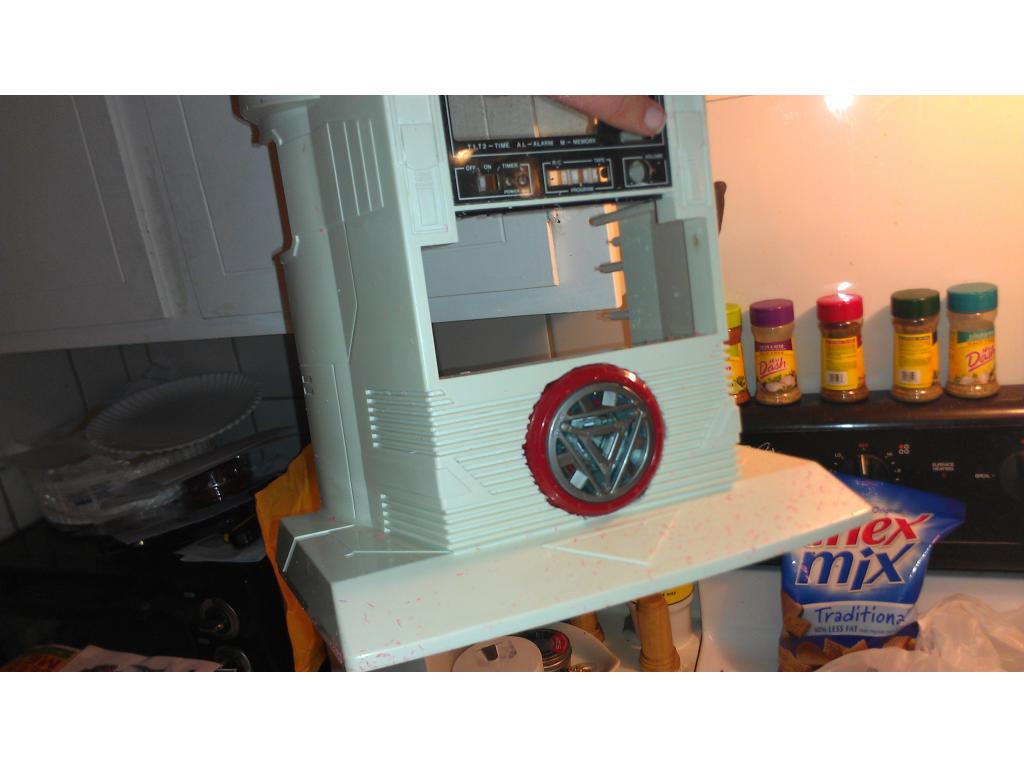
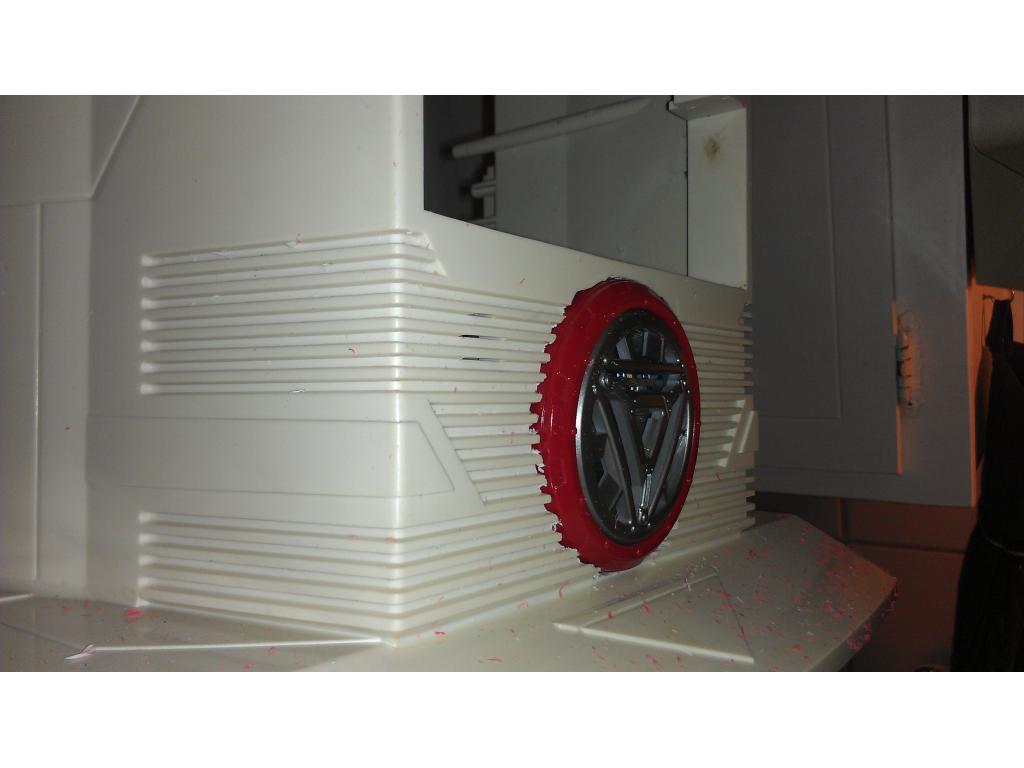
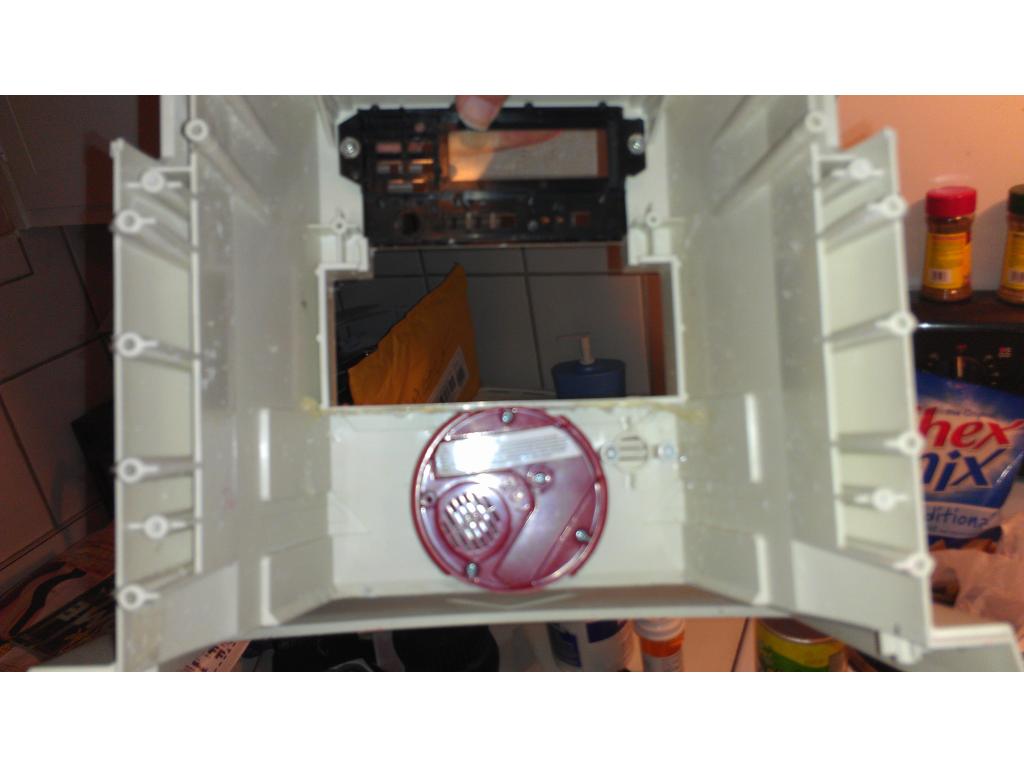
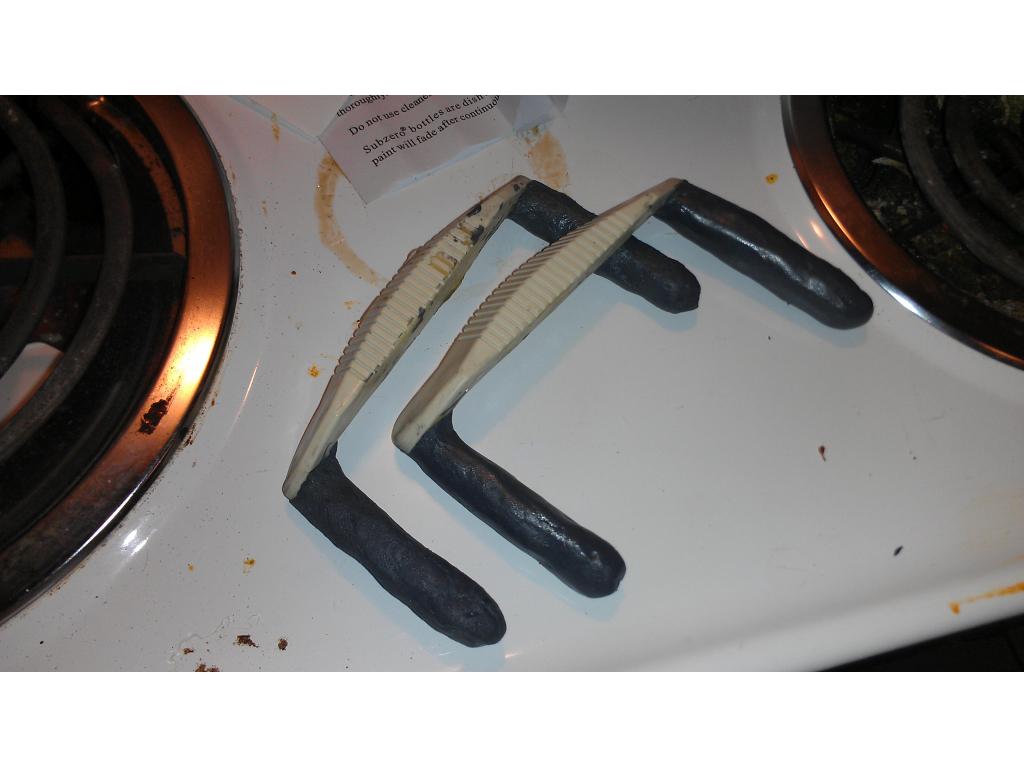
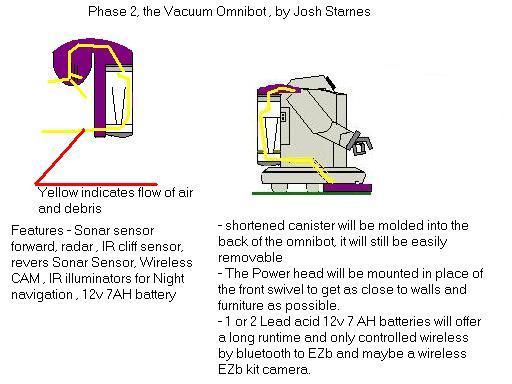
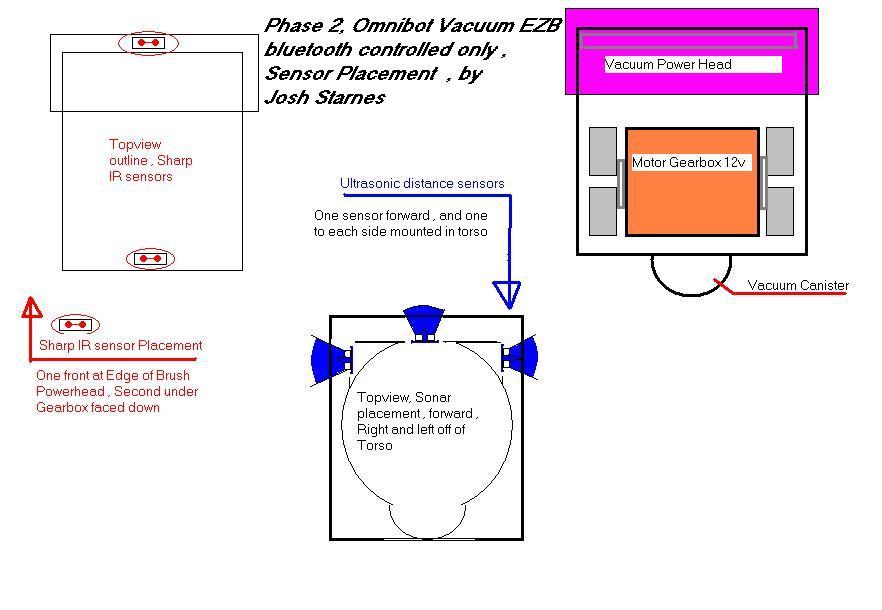
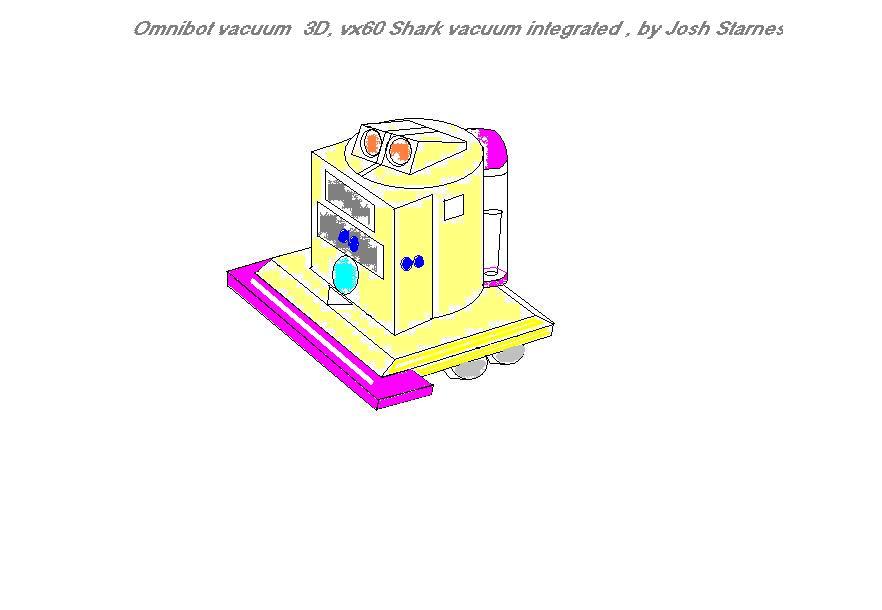
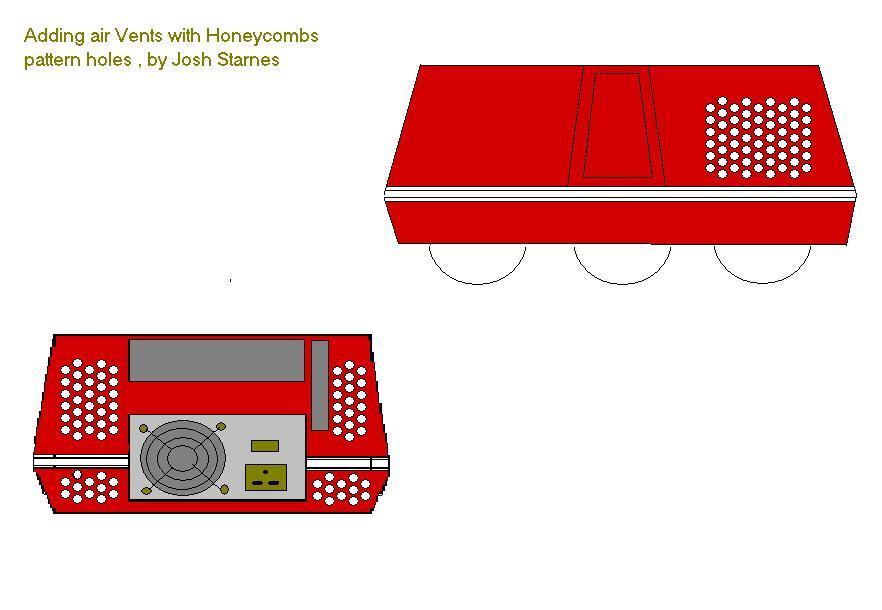
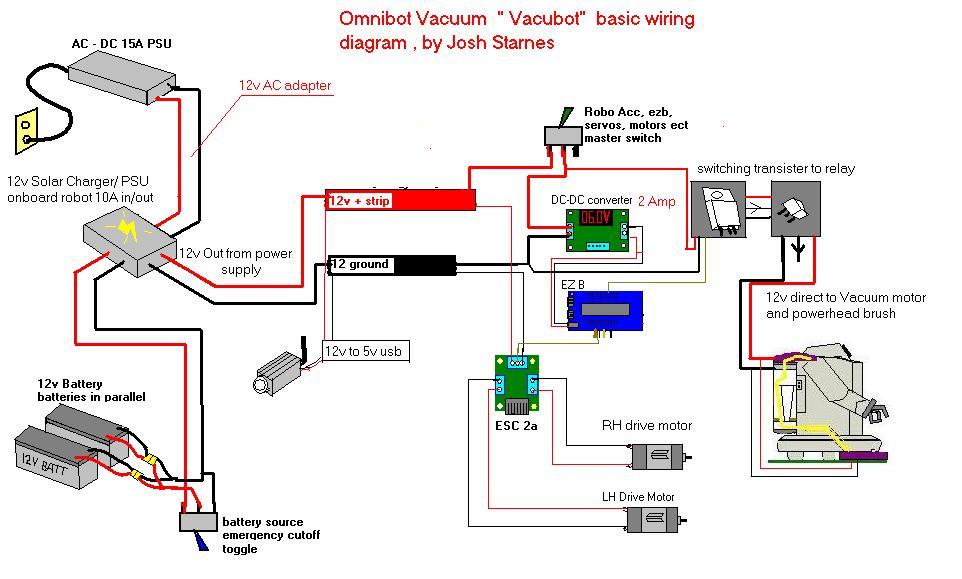
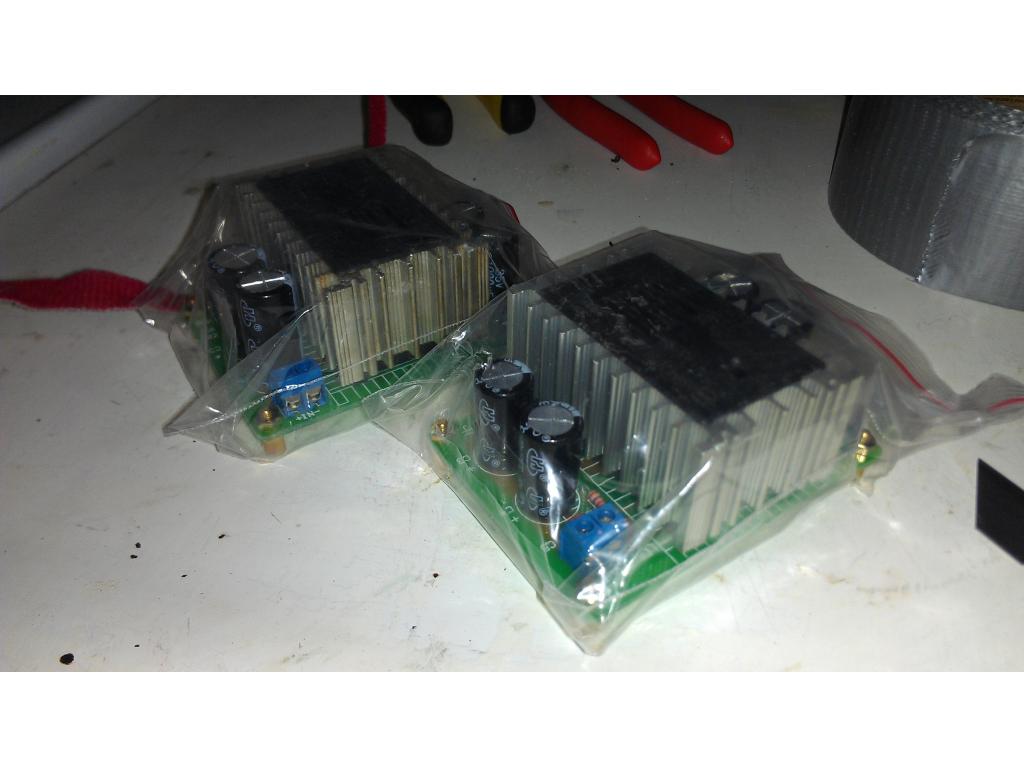
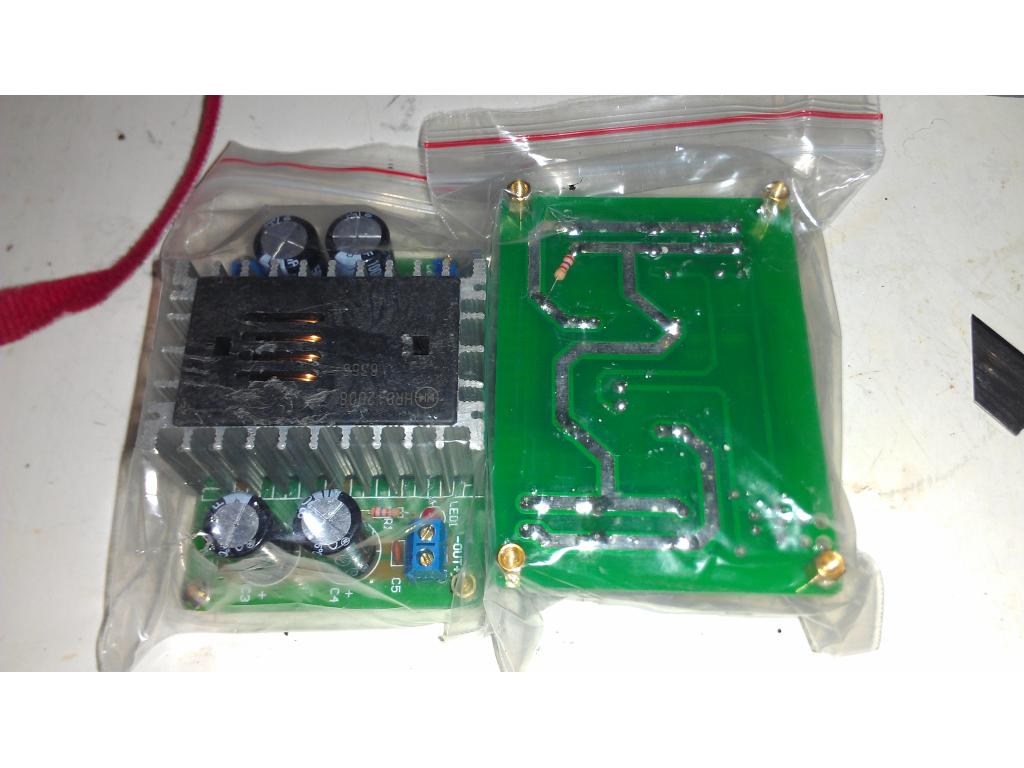
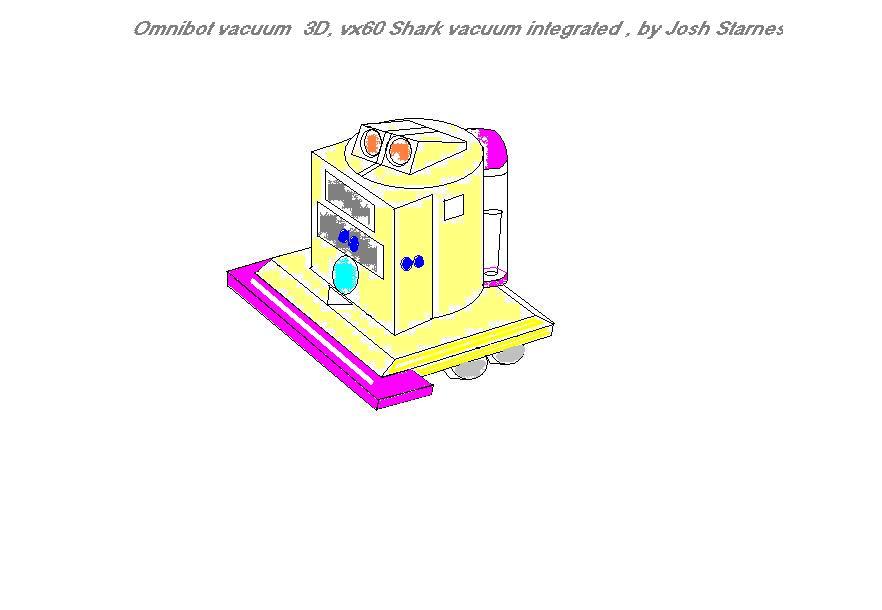
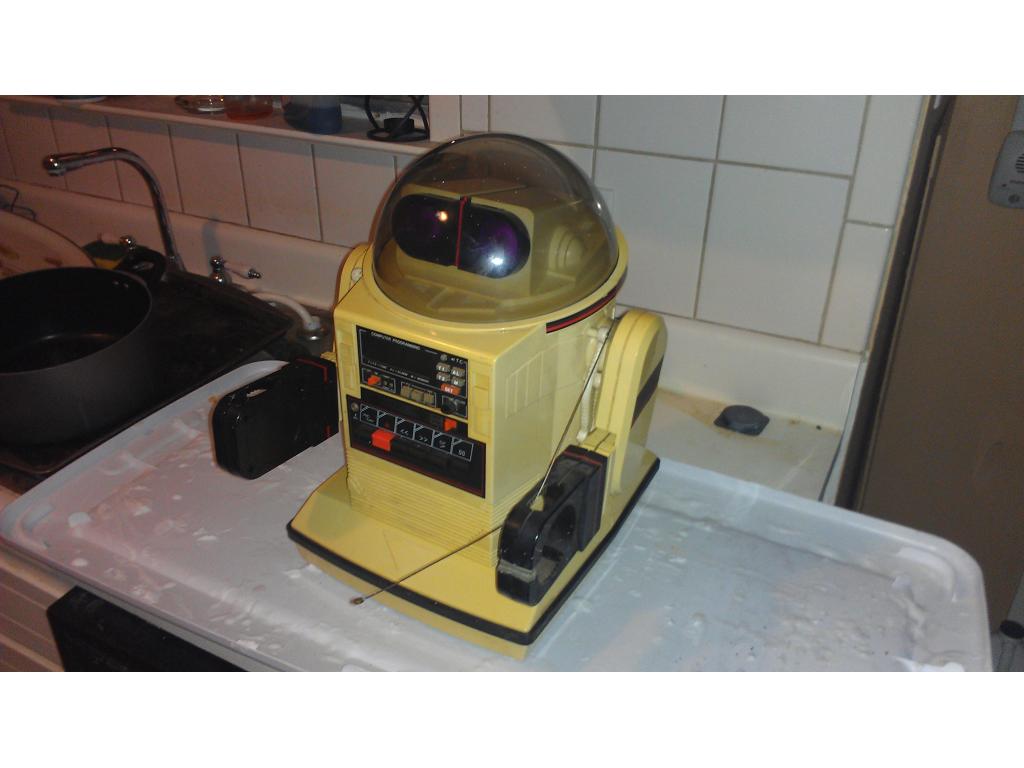
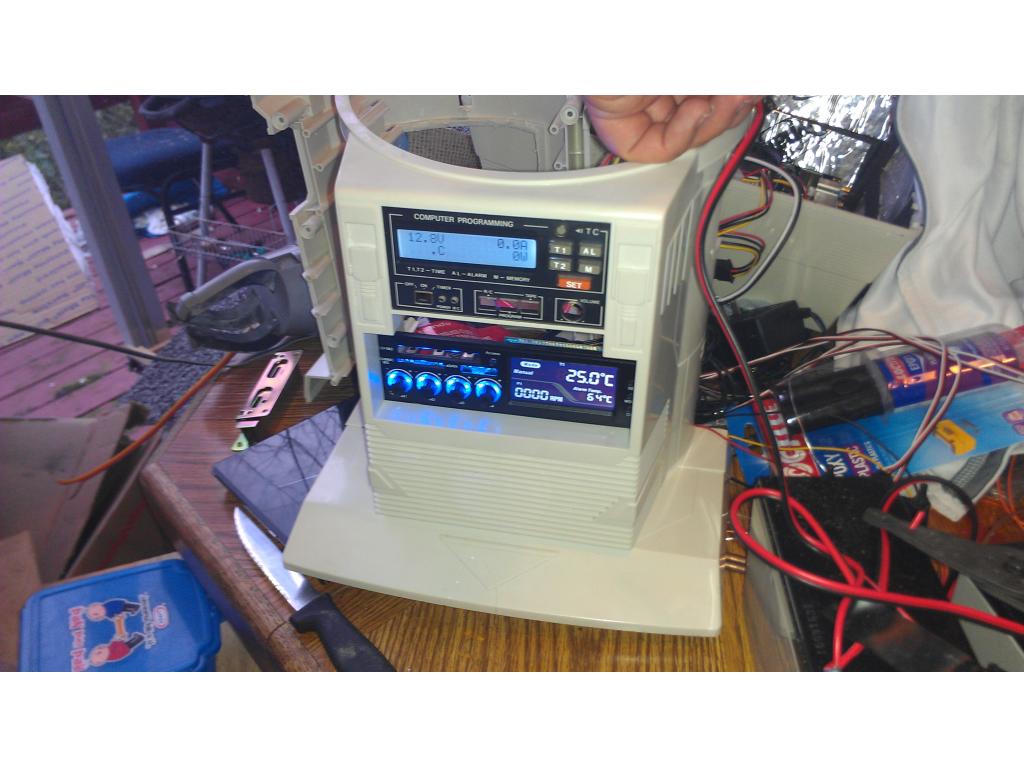
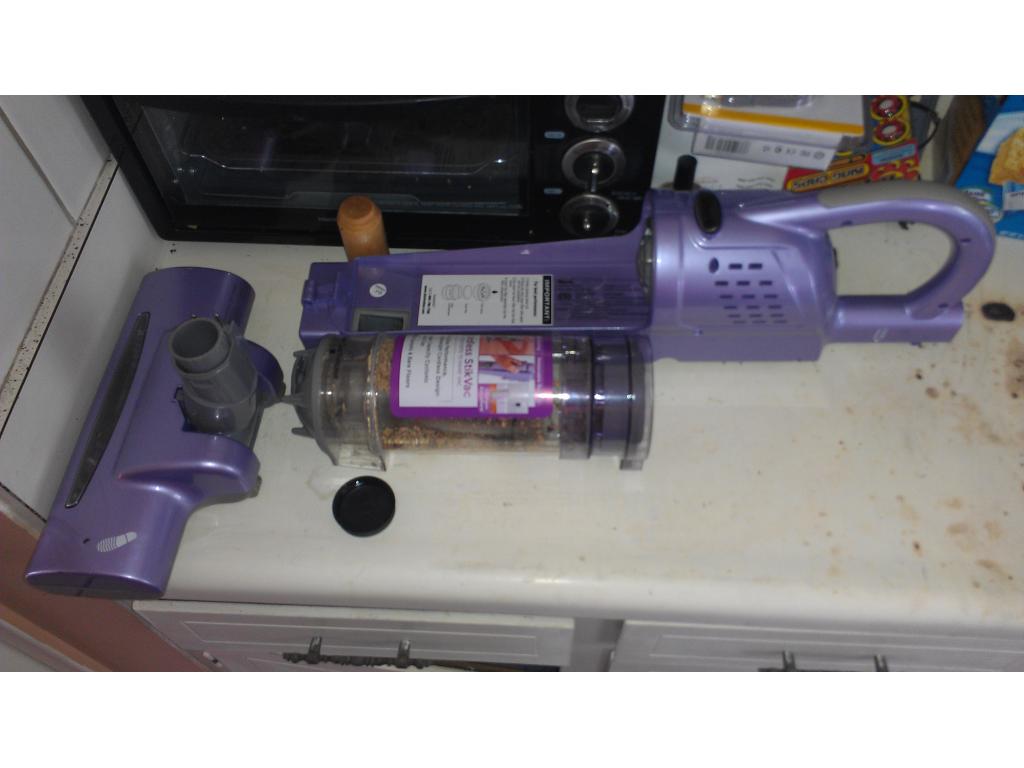
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.

By jstarne1
— Last update

Discover more robots
Nyapaysolo's Jo Zero Moving To Synthiam Soon
Expand ez-robot HSWB04F controller ports for Jo Zero humanoid, hack or add servo inserts to support 22 servos
Cardboardhacker's Ez-Ollie
ez-Ollie: recreate Sphero Ollie with a simple low center-of-gravity build for stable rolling, easy forward drive and...
David's Ai Dino Robot
Upgrade a toy walking dinosaur with an EZ-B brain to create a smart robotic pet, unlocking expanded behaviors and...

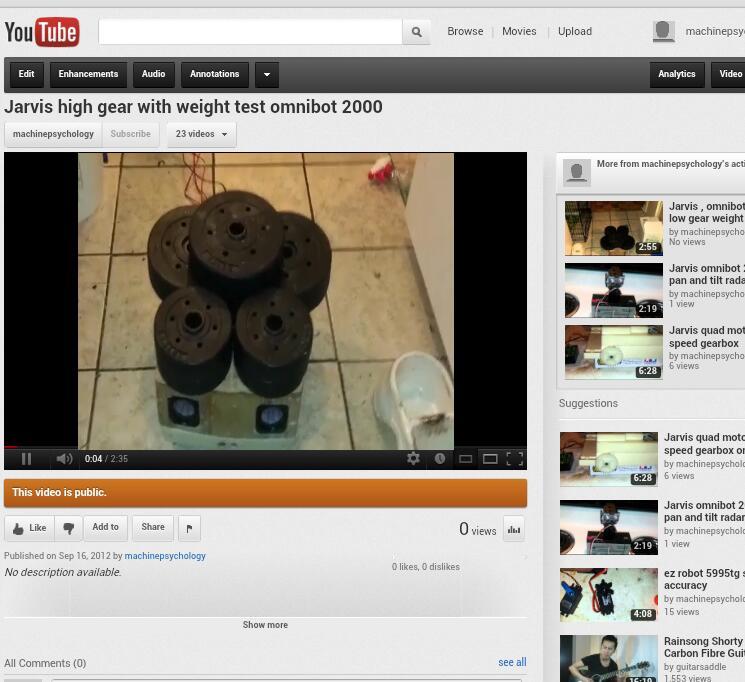
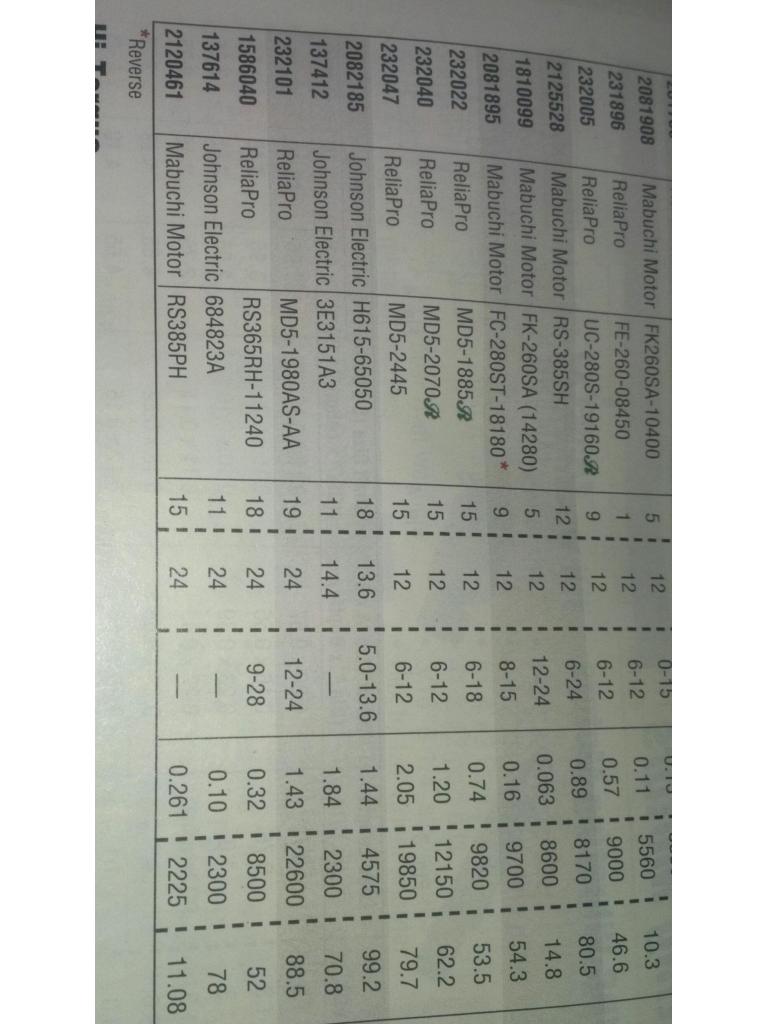
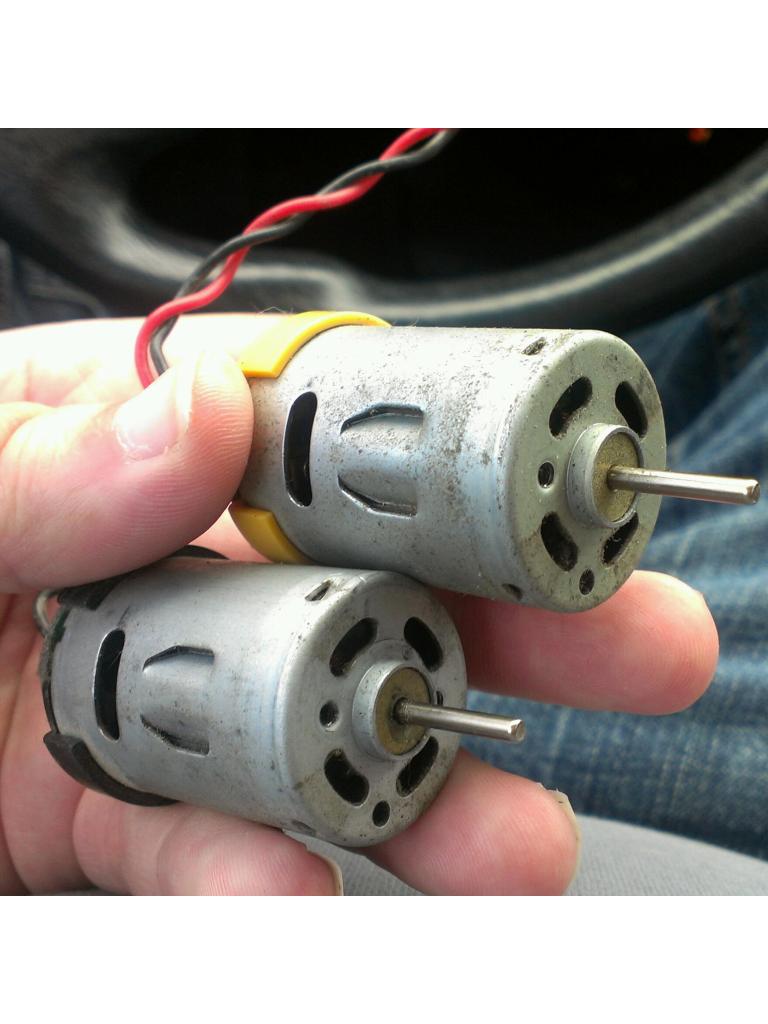
wow 60 lbs thats alot of weight,JOSH have you tried my motors i sent you,they will handle about 70 or more pounds ,using 2 of them,plus with gear box ratio will be more
If fI can make the extra room I would love to try those motors.
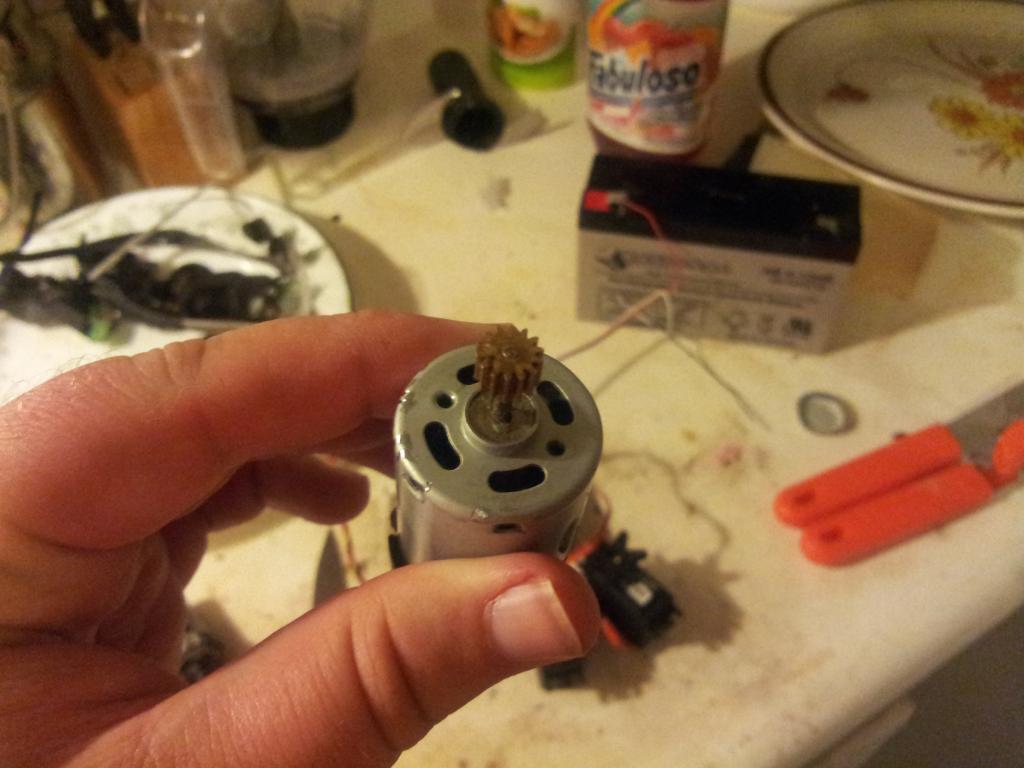
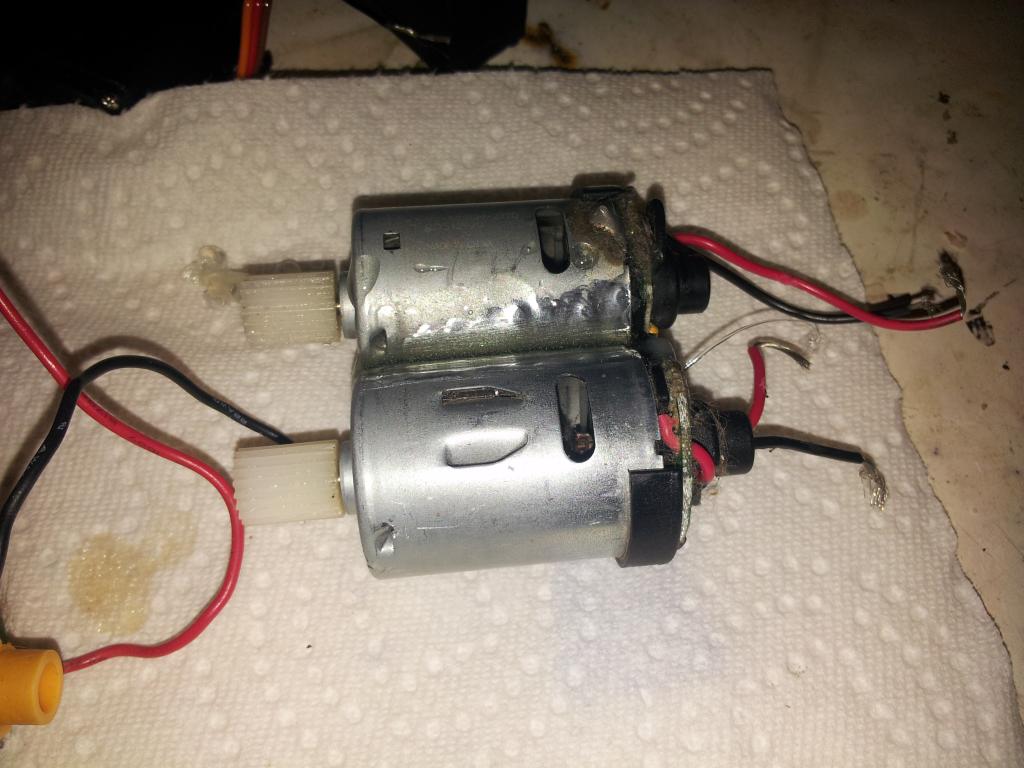
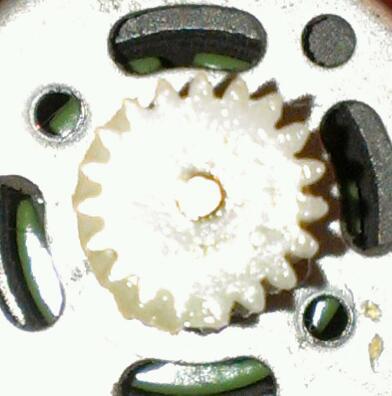
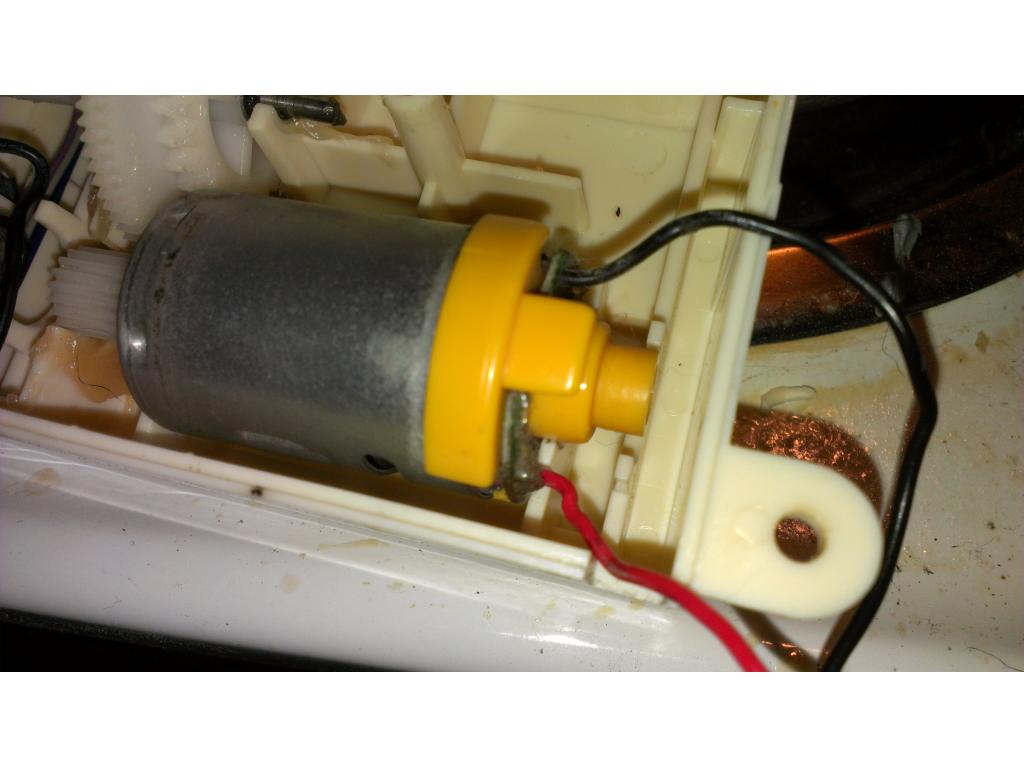
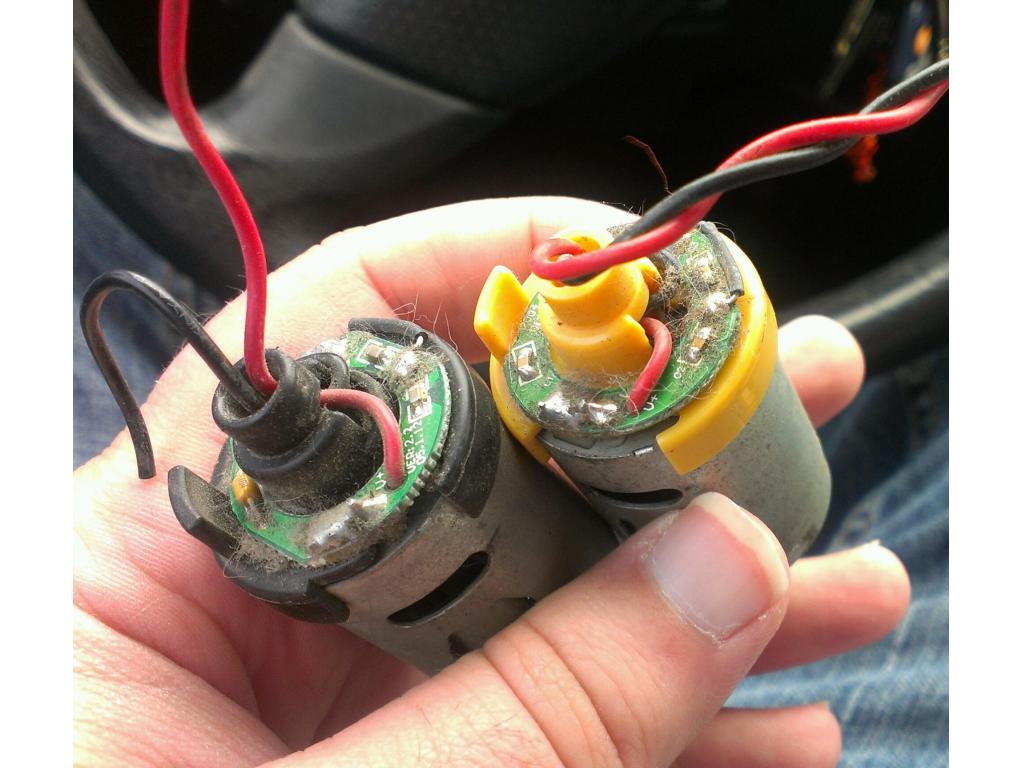
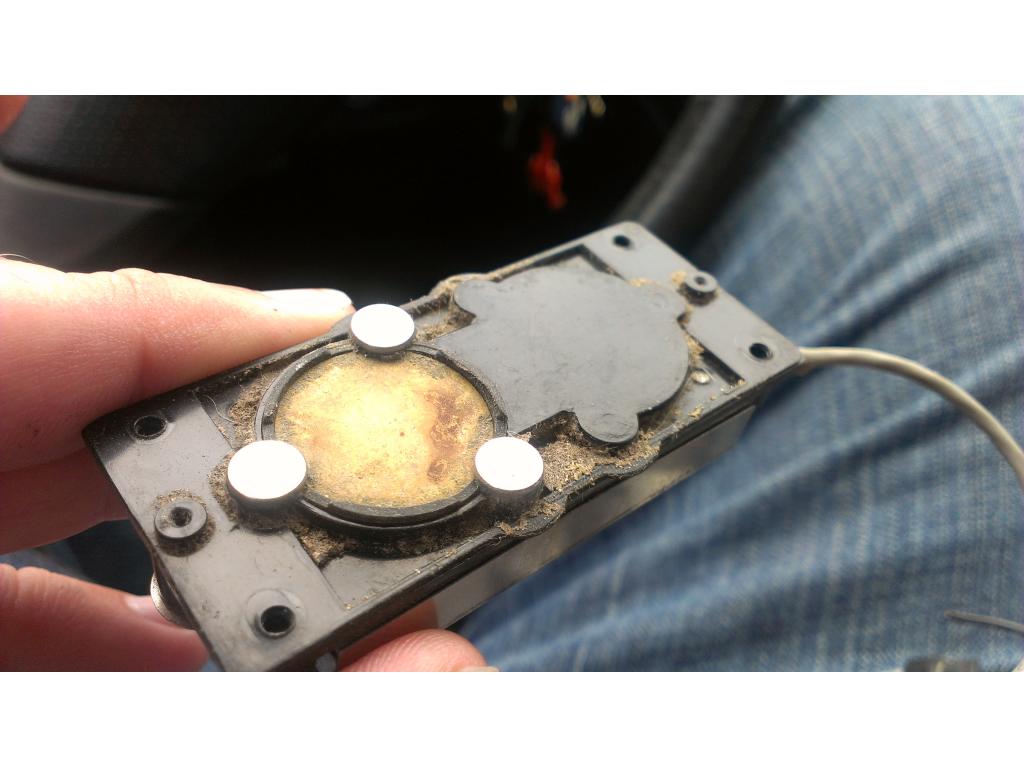
motors will fit,only little longer,but 2 together will fit ok ,with about 1/2 inch to spare only the pinon gear needs to be changed i have tried it on mine,until i changed over to tracks,needs 12 volts i think it has magnetic encoder on it,working on a desgn to interface to it,or has a analog output to EZB
I only see power wires , how do I connect a encoder signal?
maybe those i sent you dont have the encoder wheelon them
Oh ok.
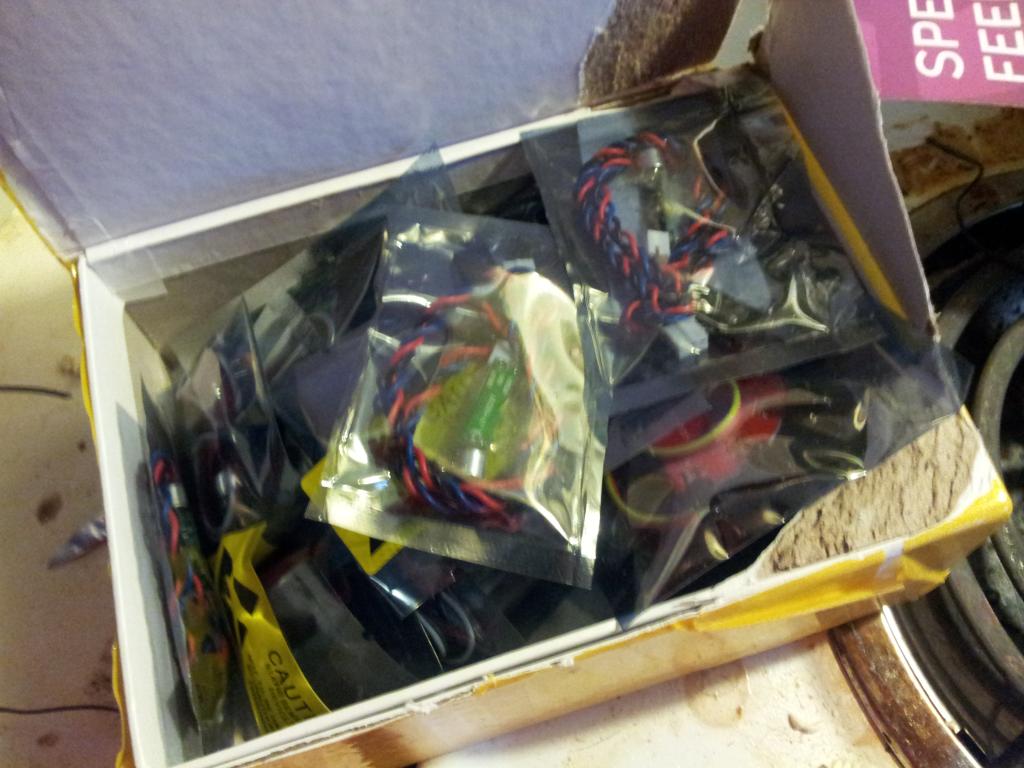
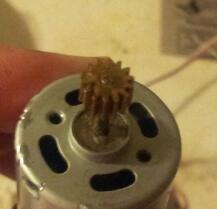
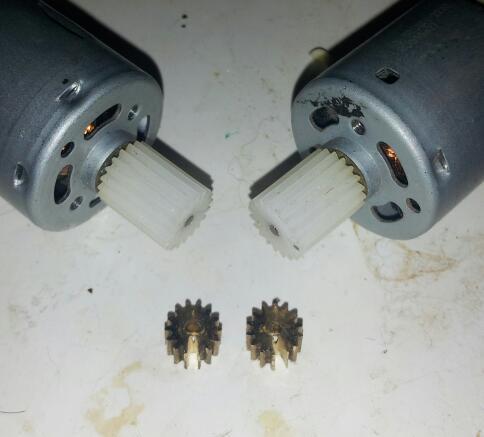
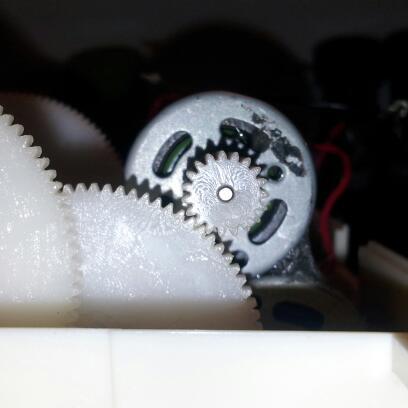
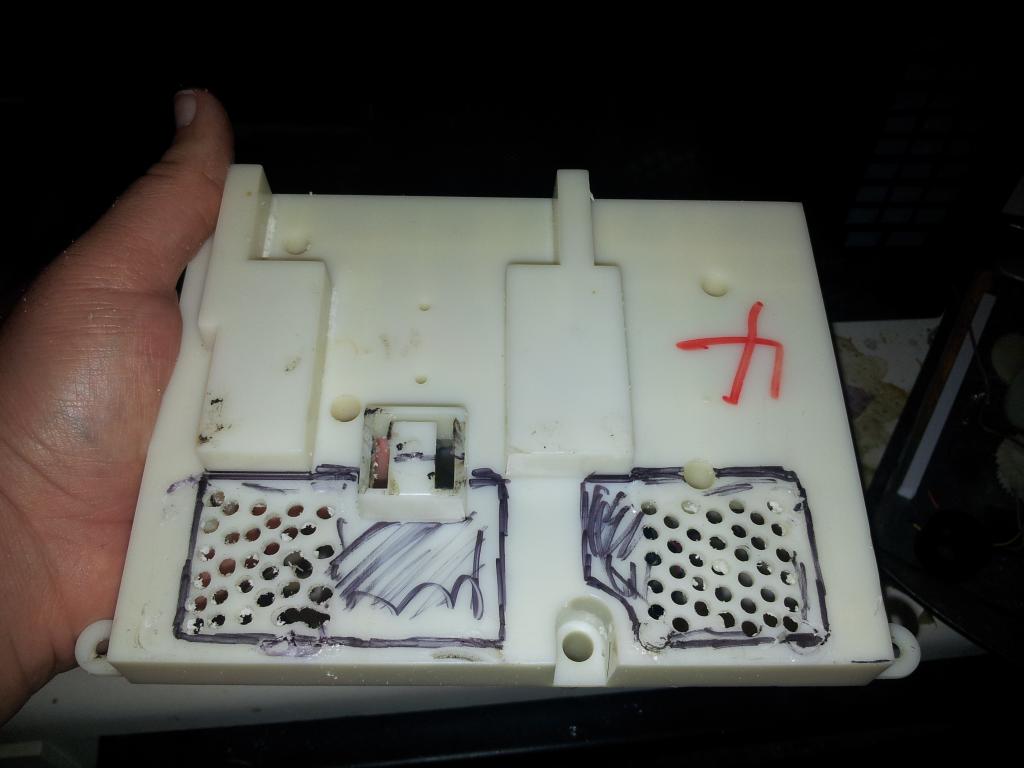
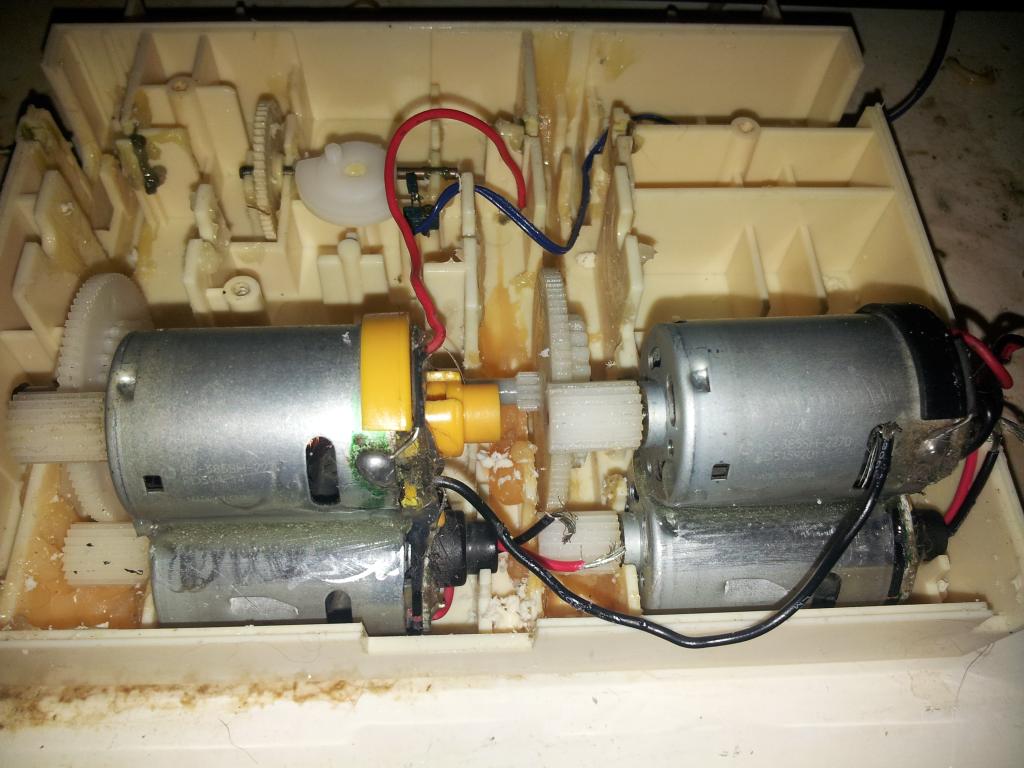
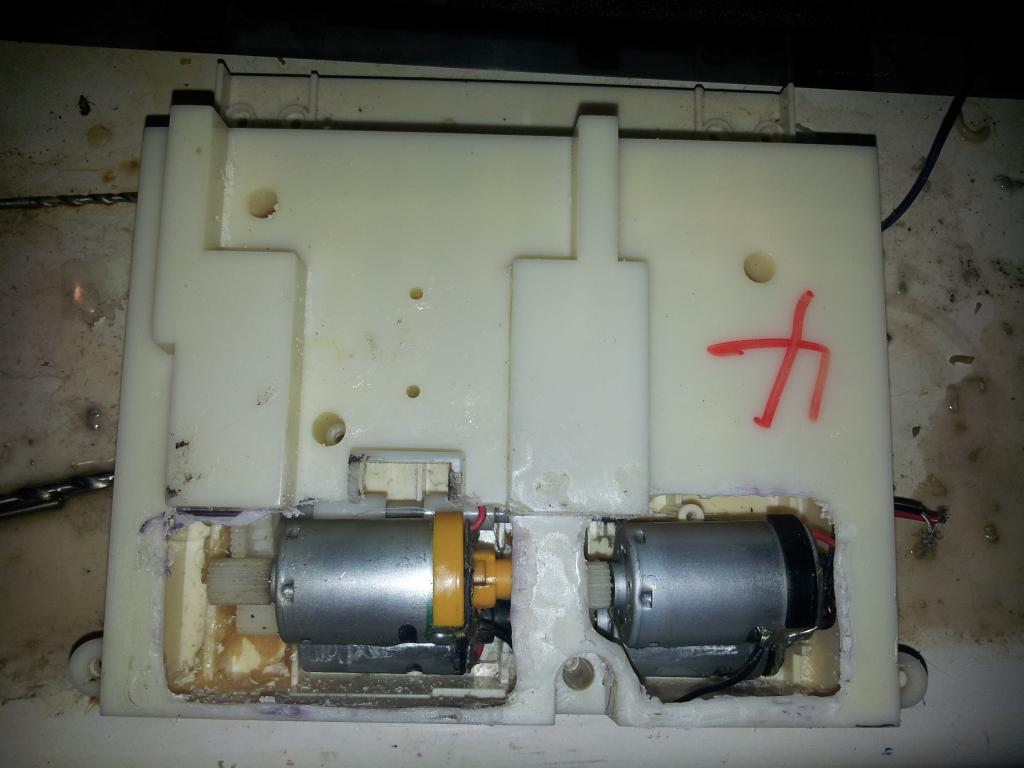
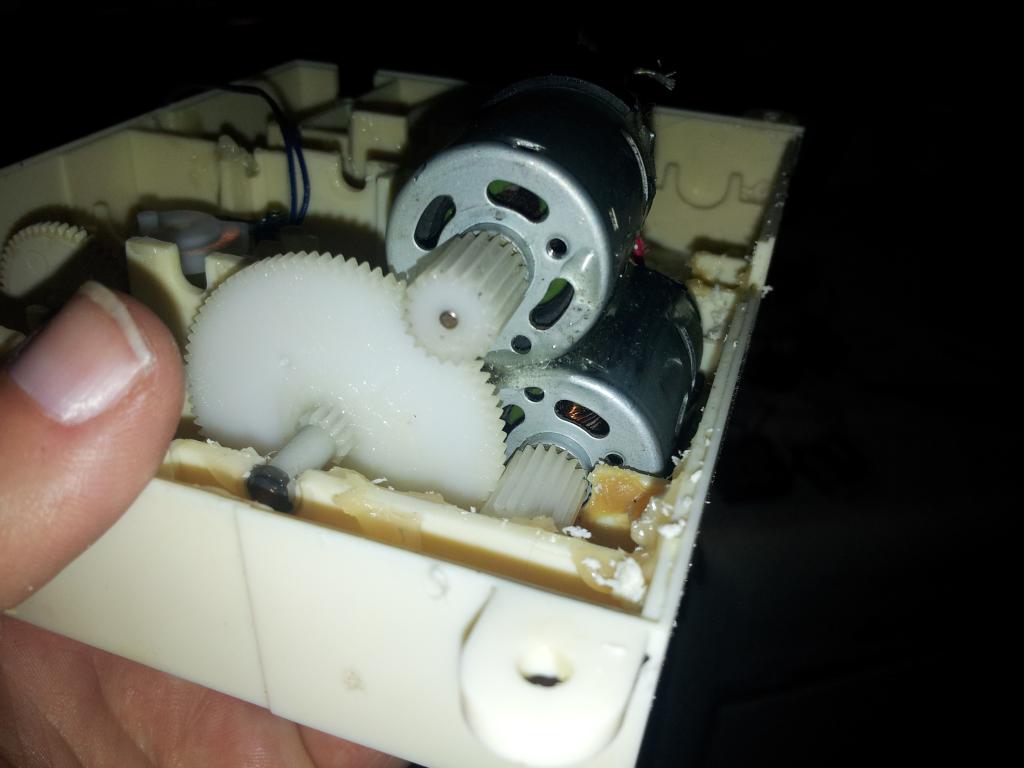
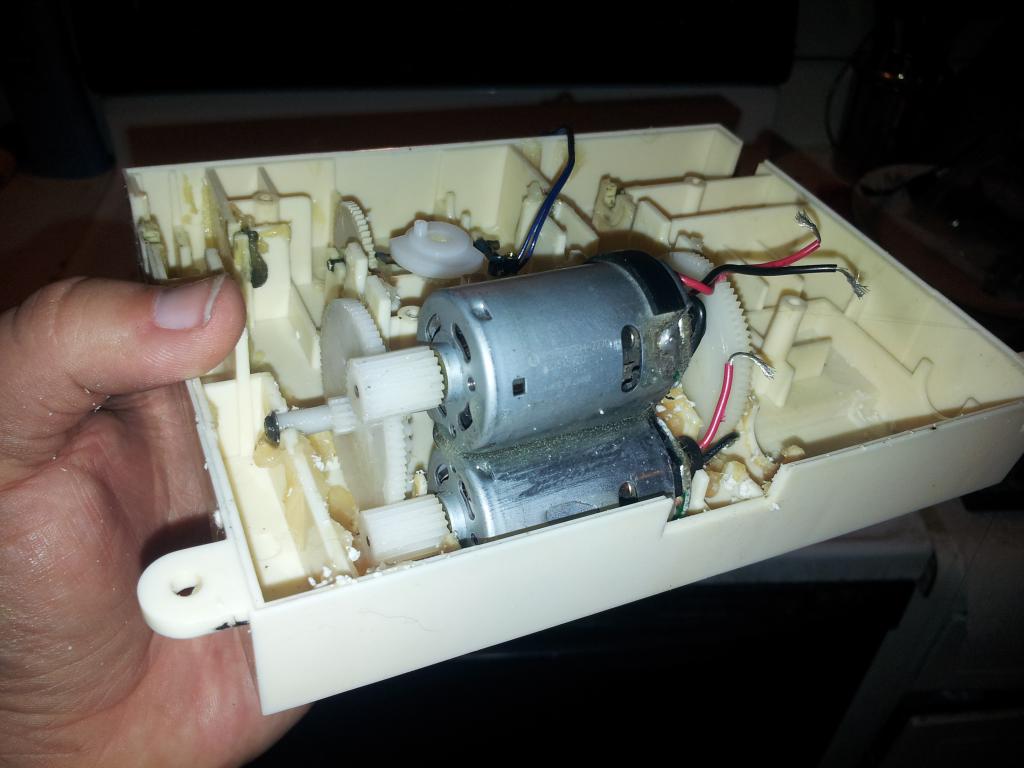
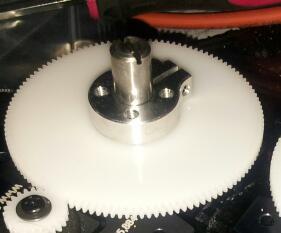
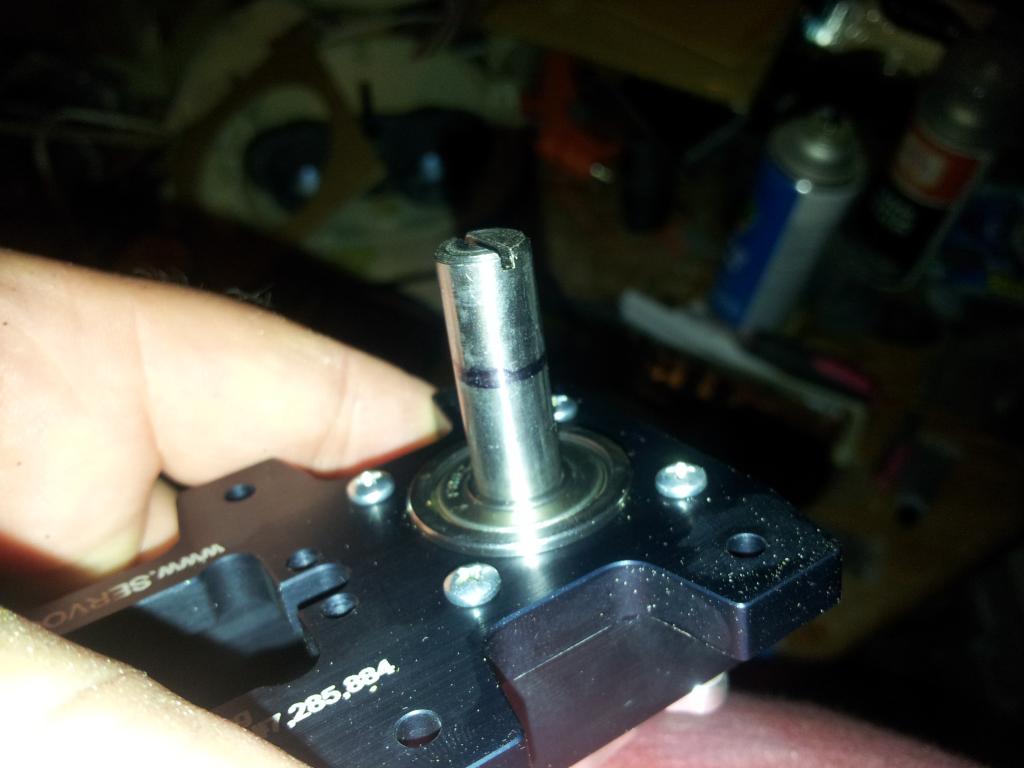
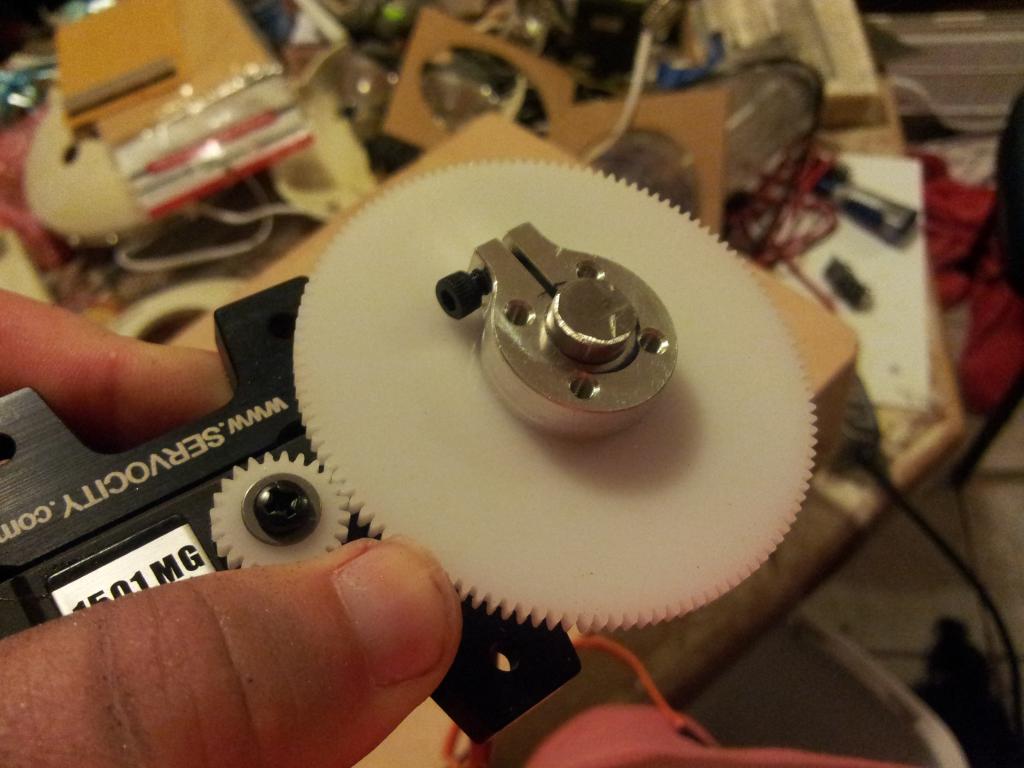
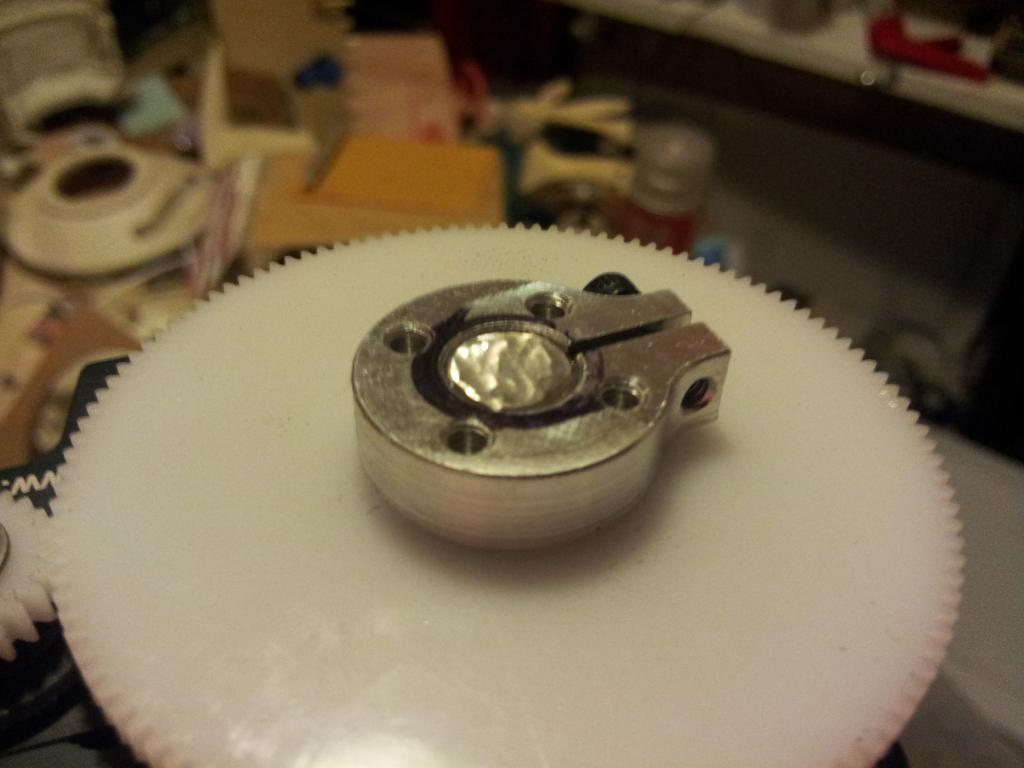
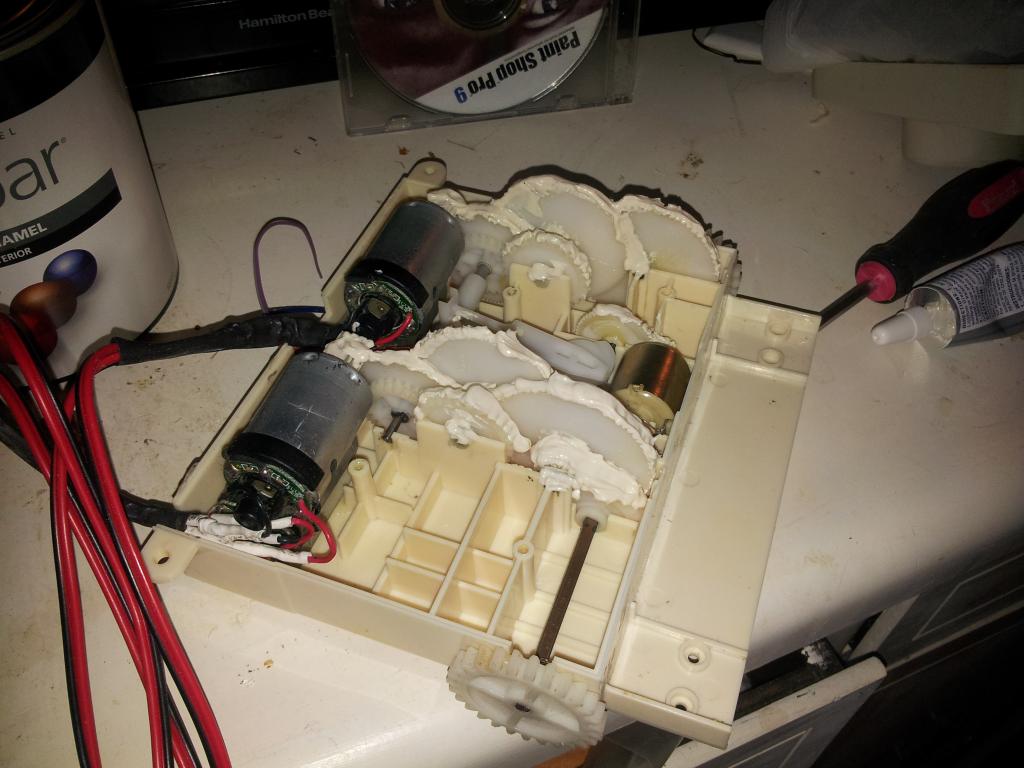
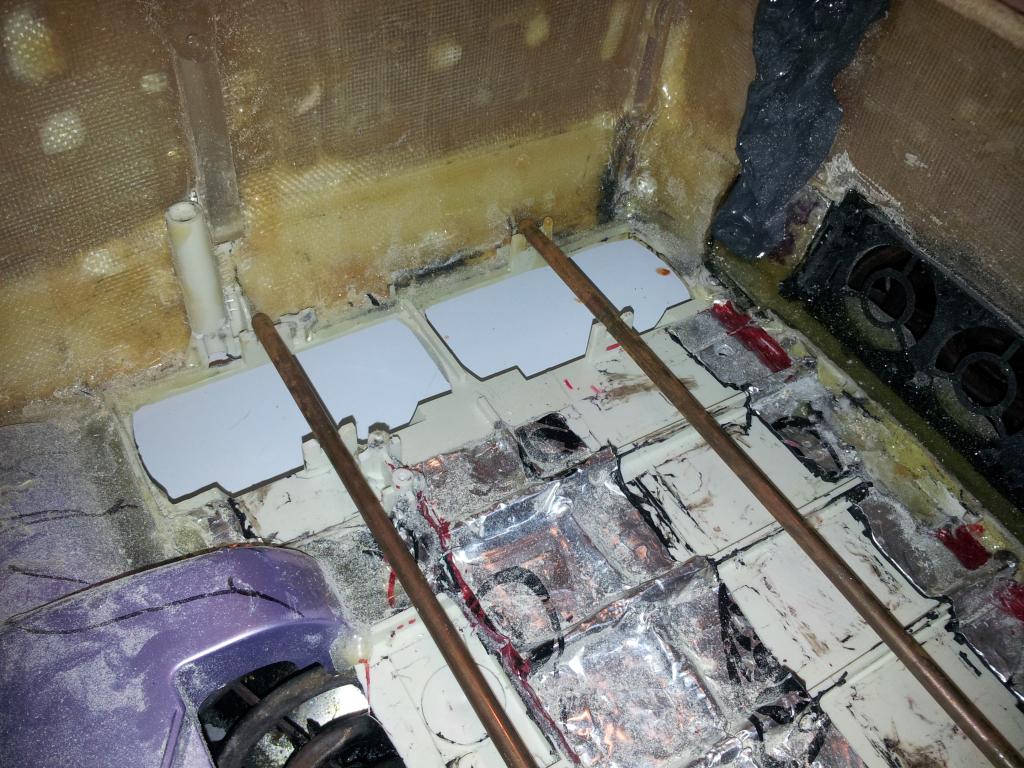
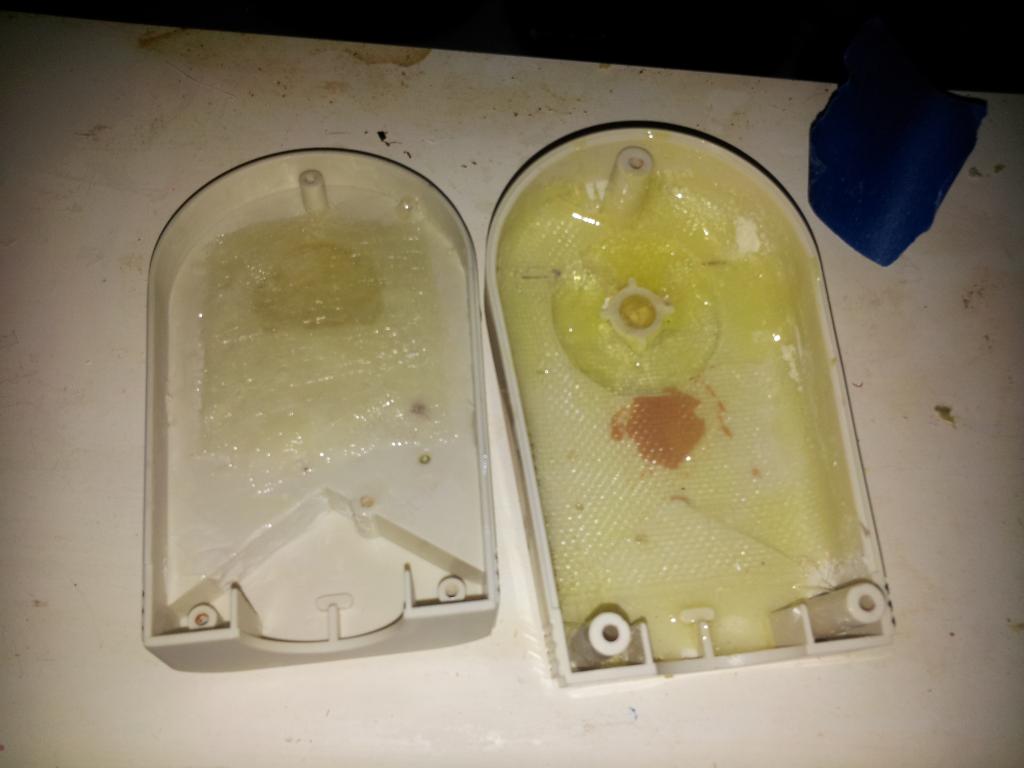
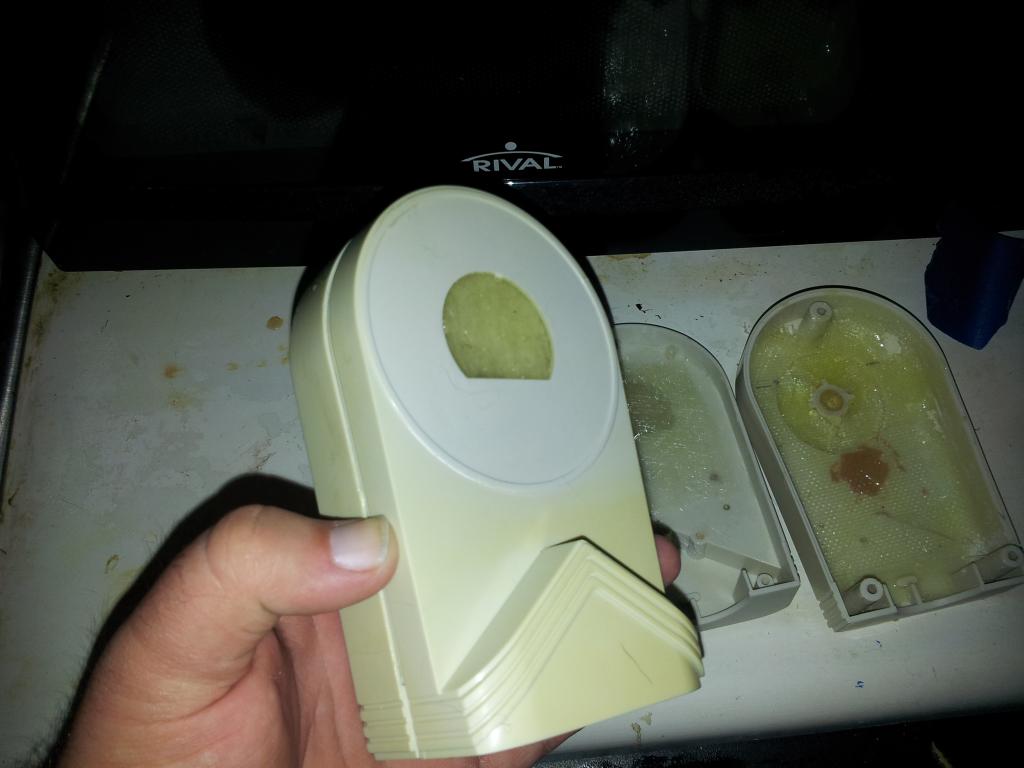
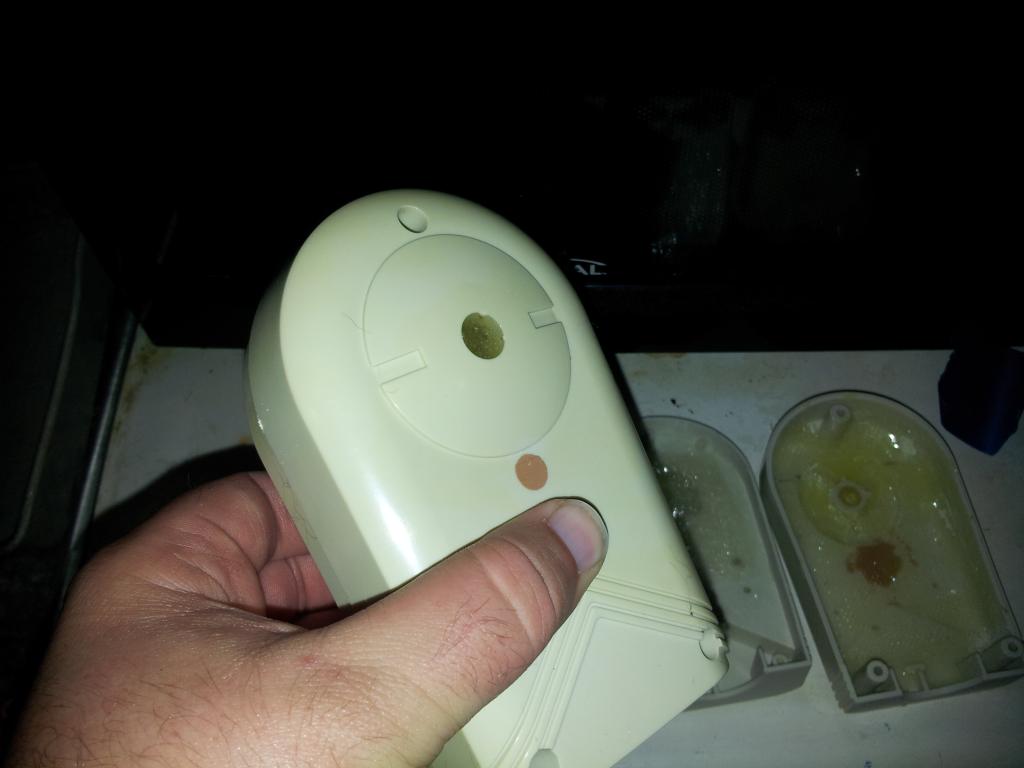
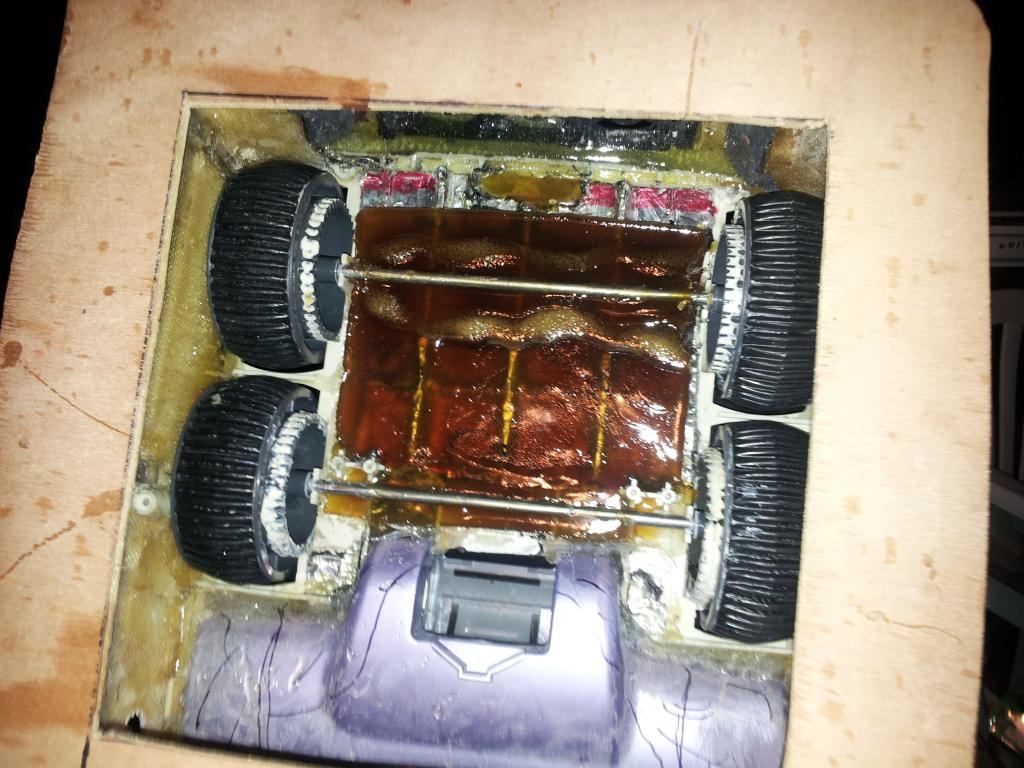
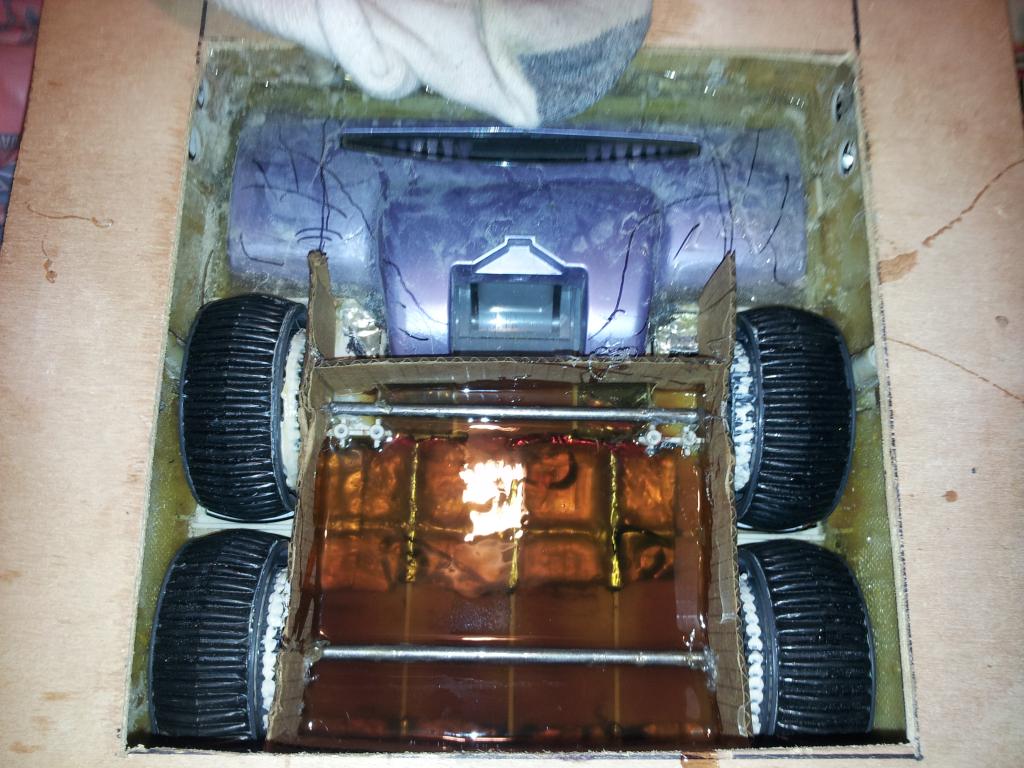
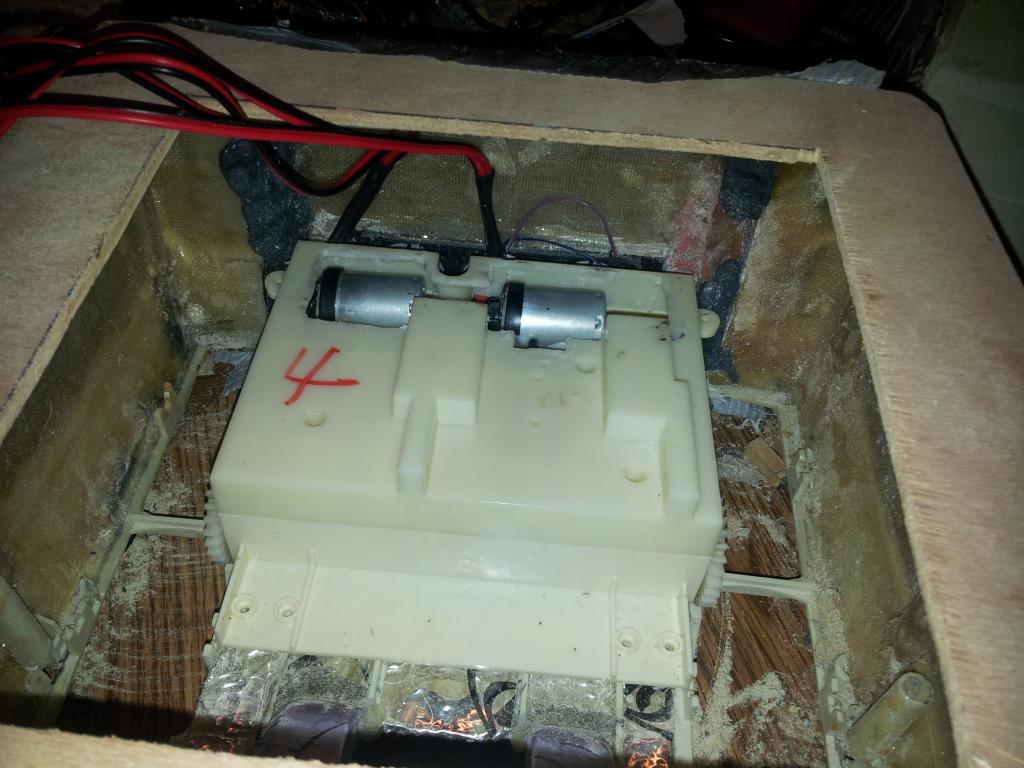
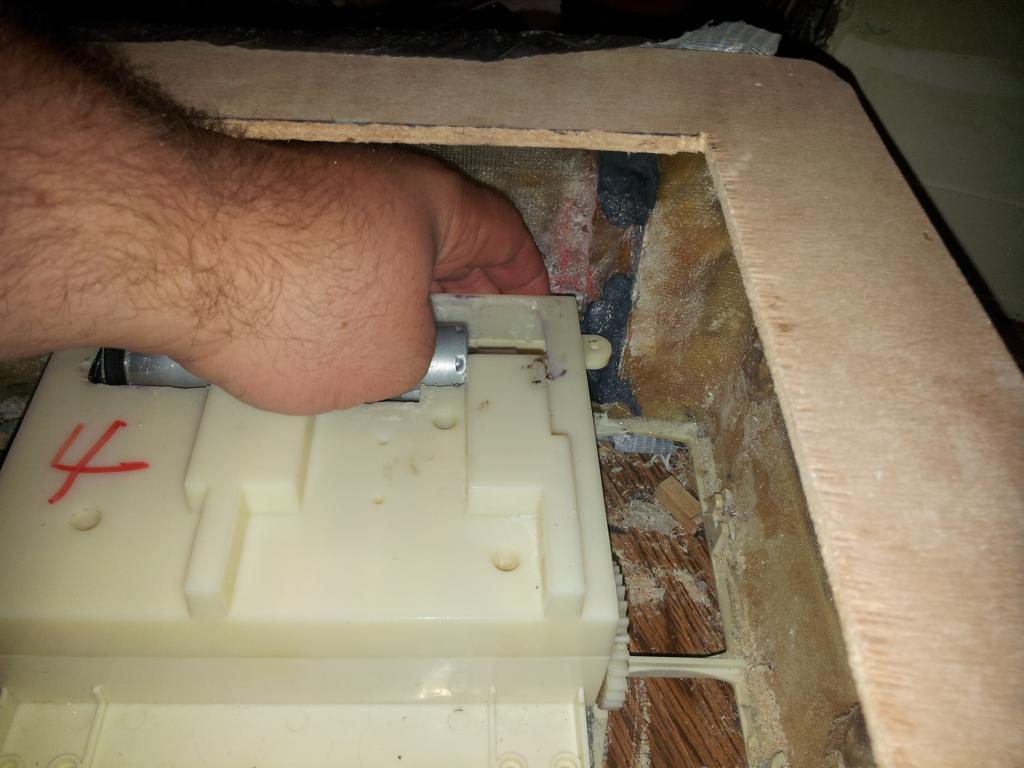
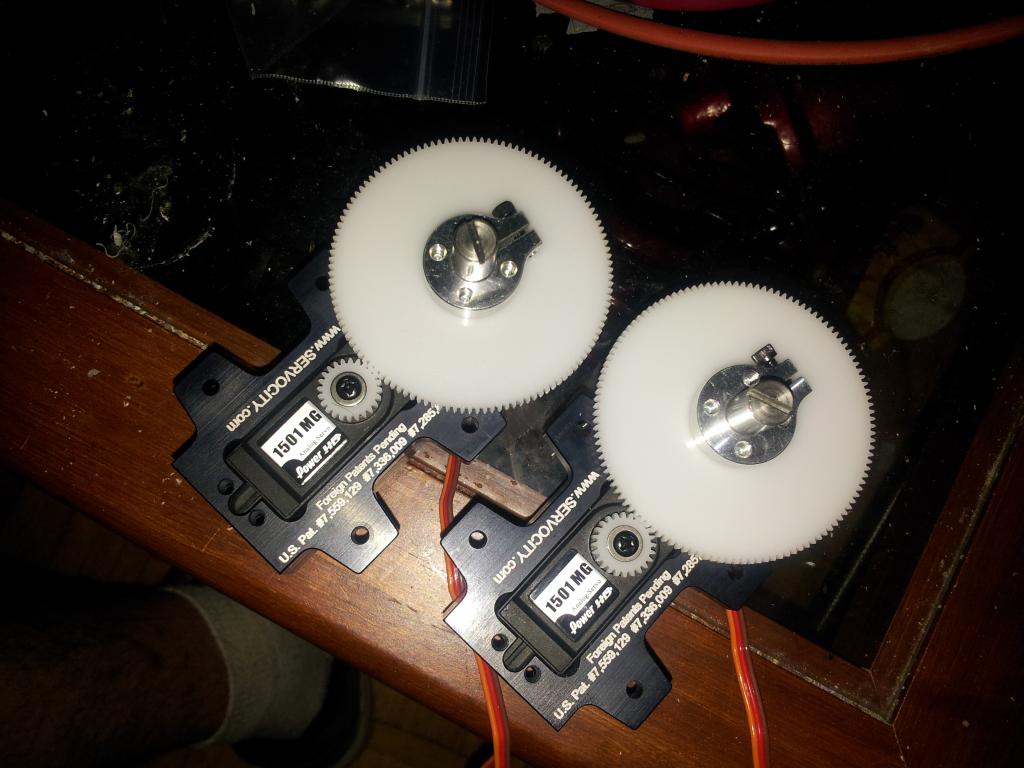
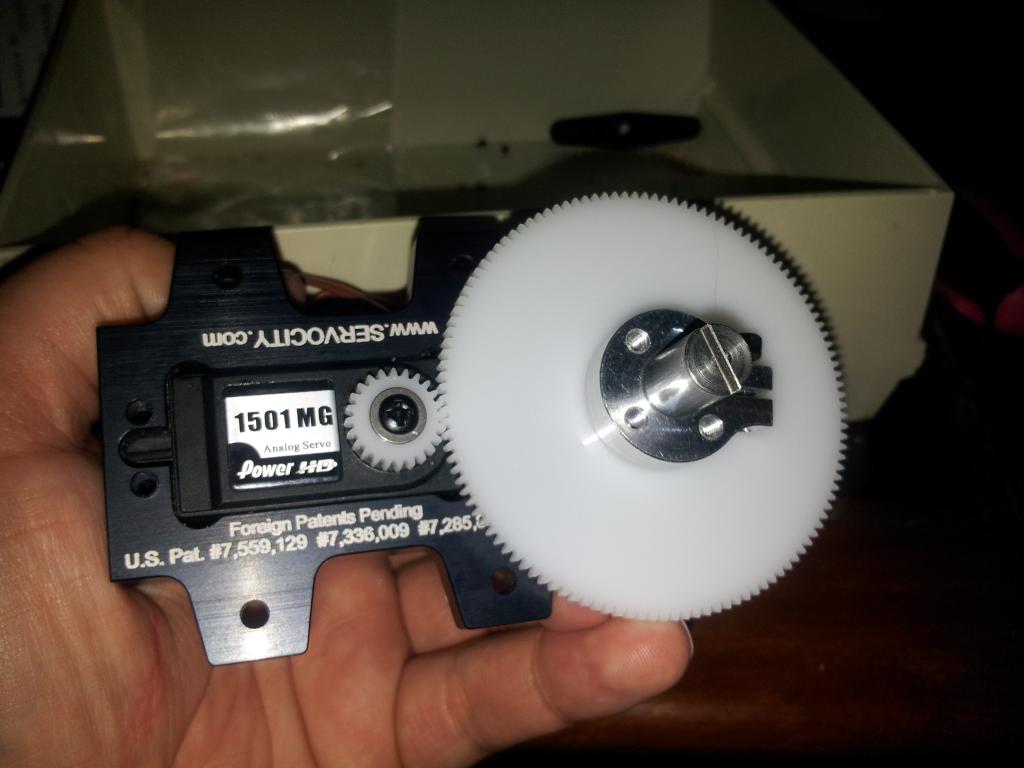
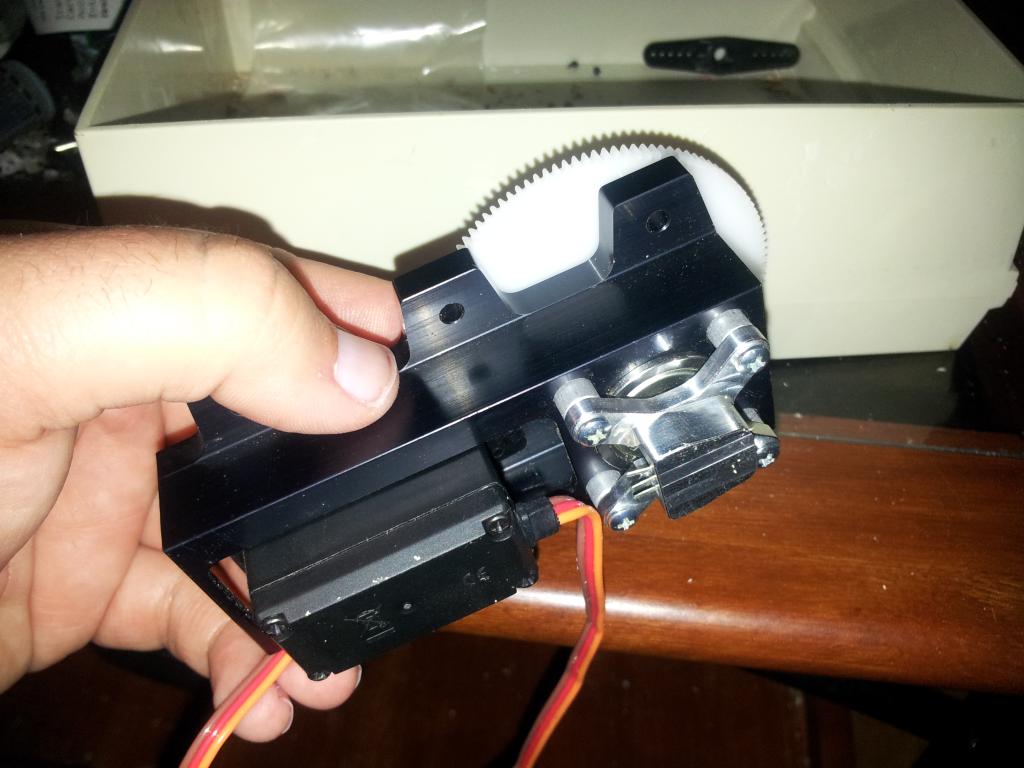
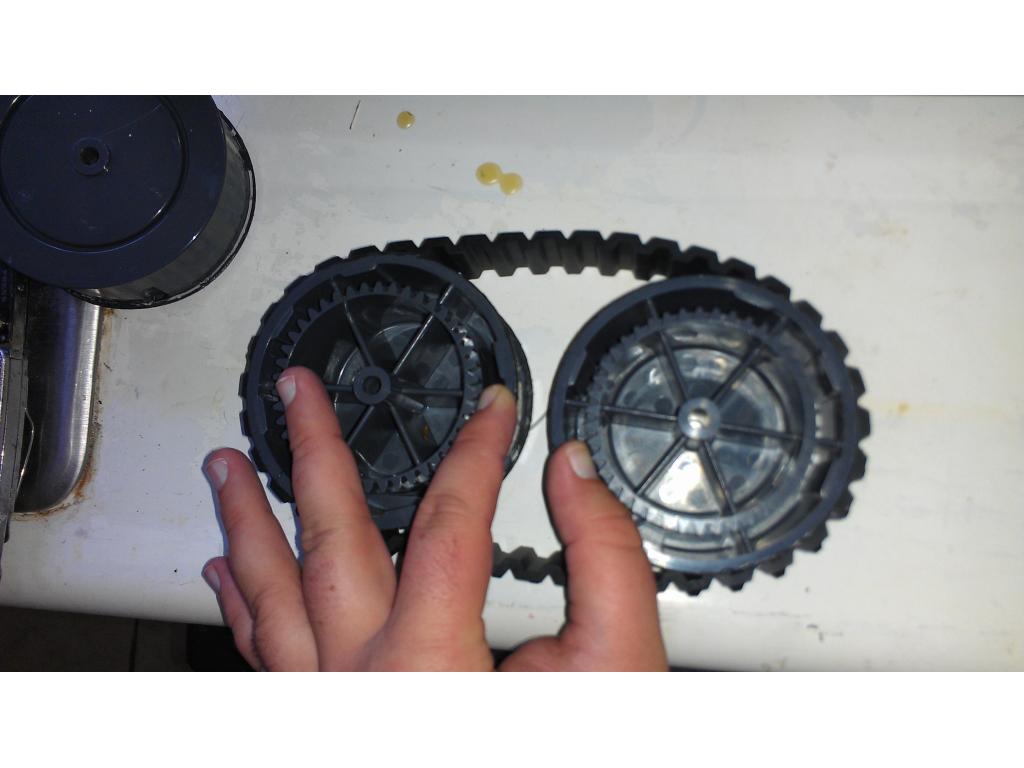
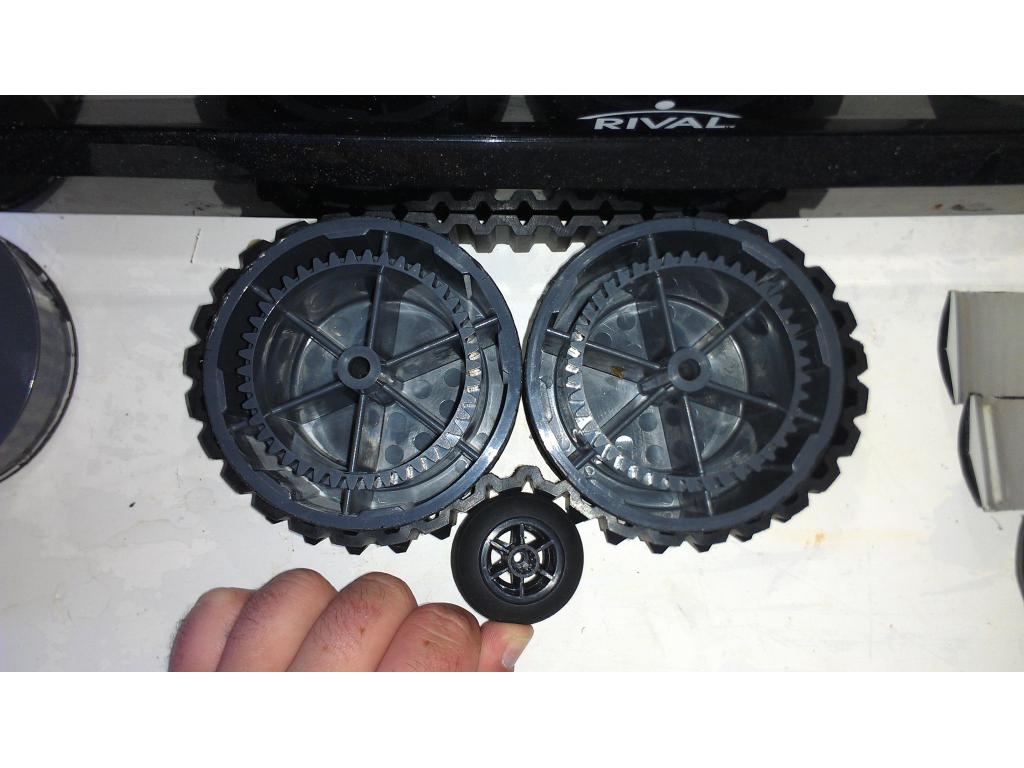
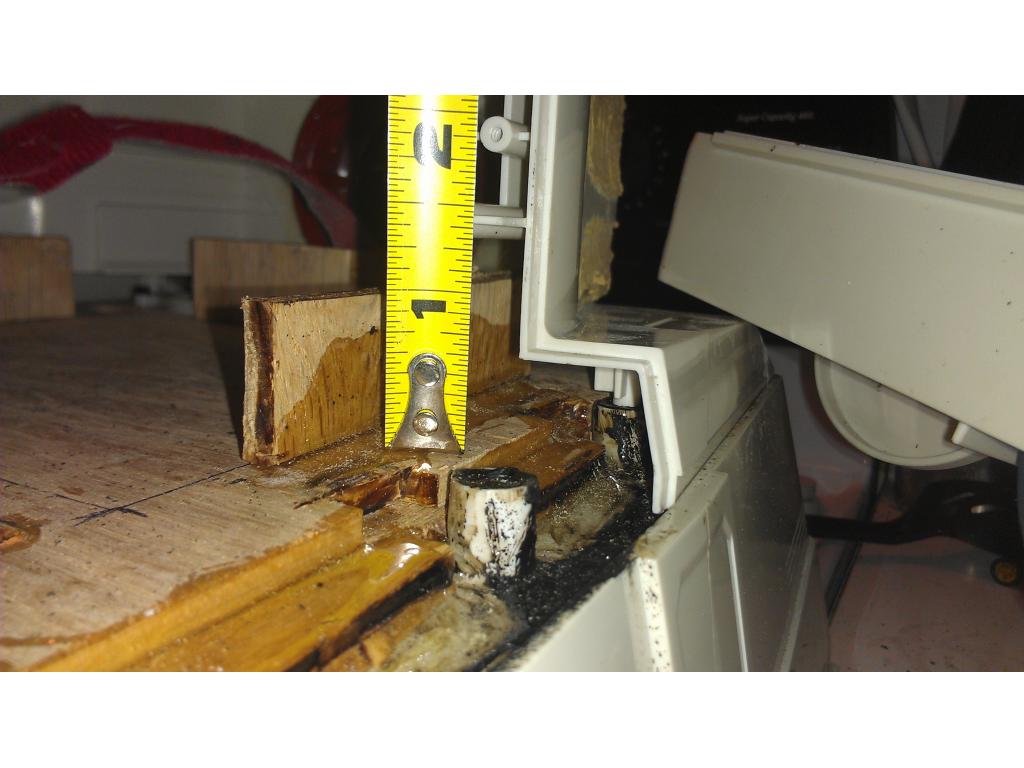
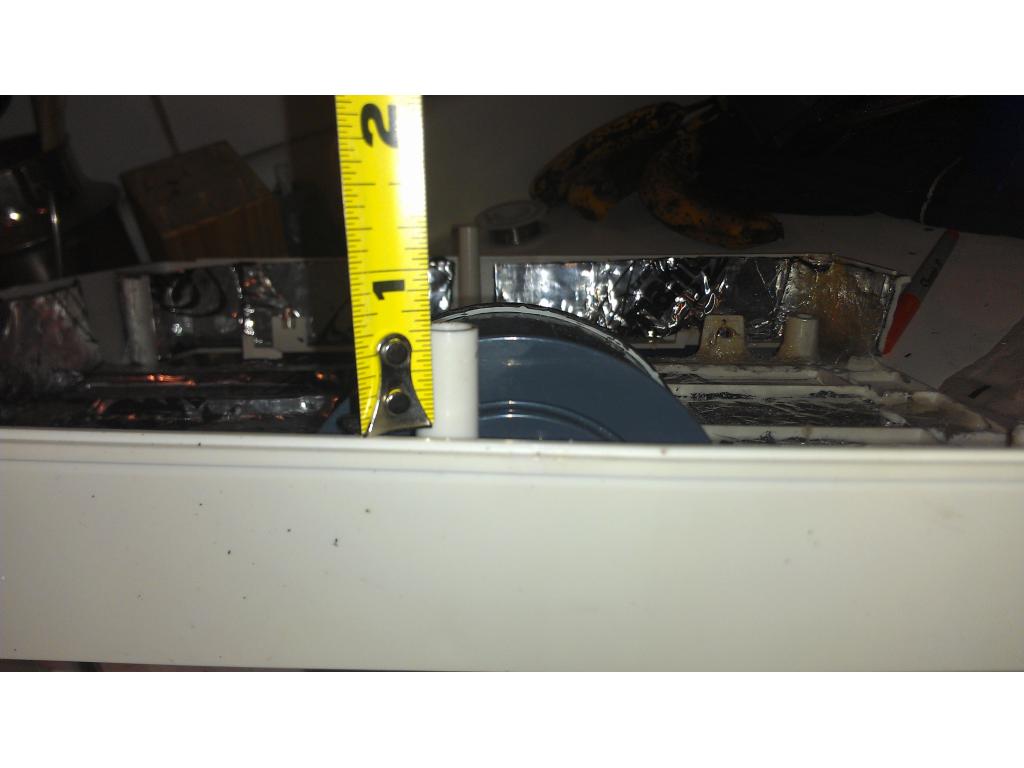
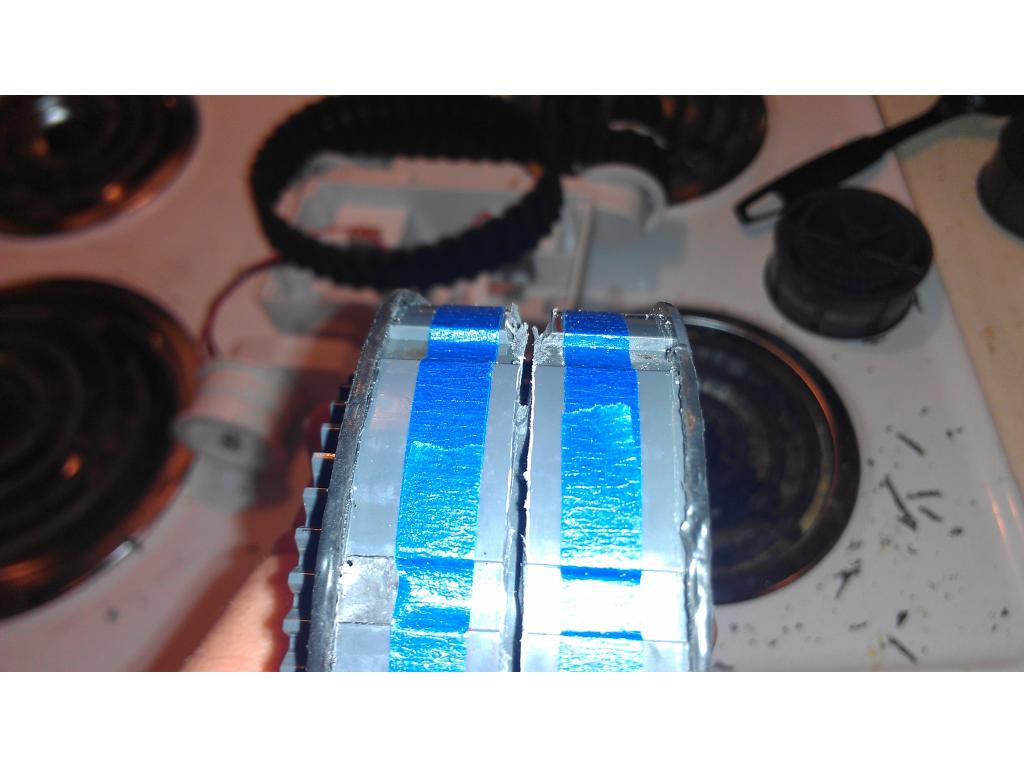
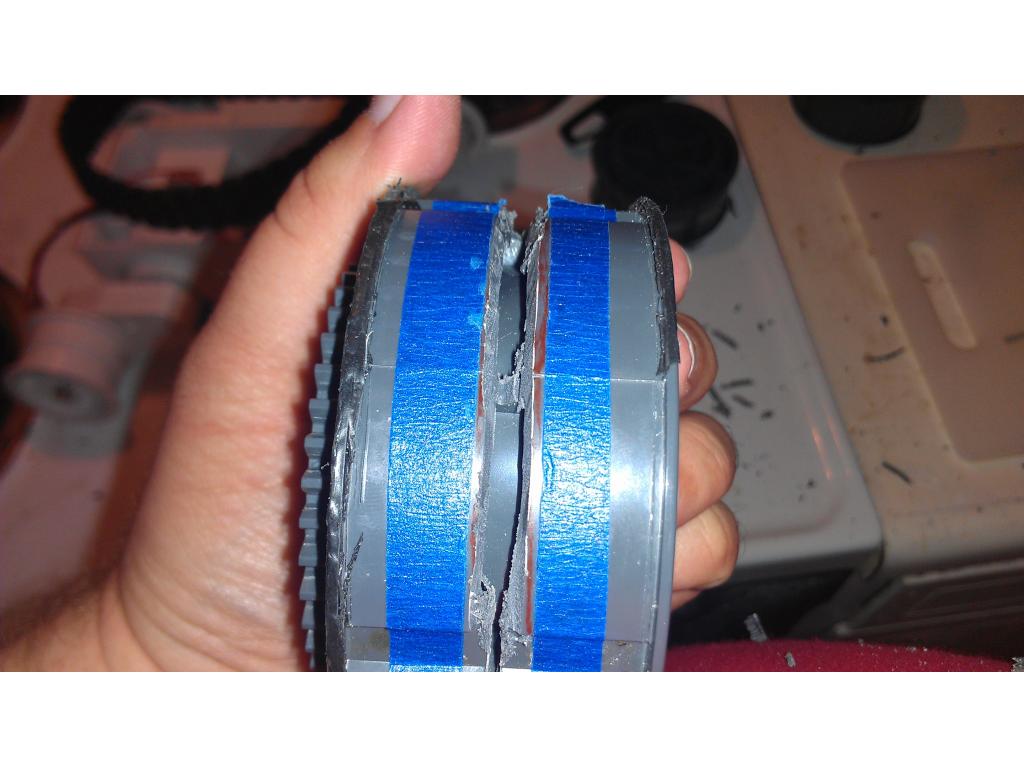
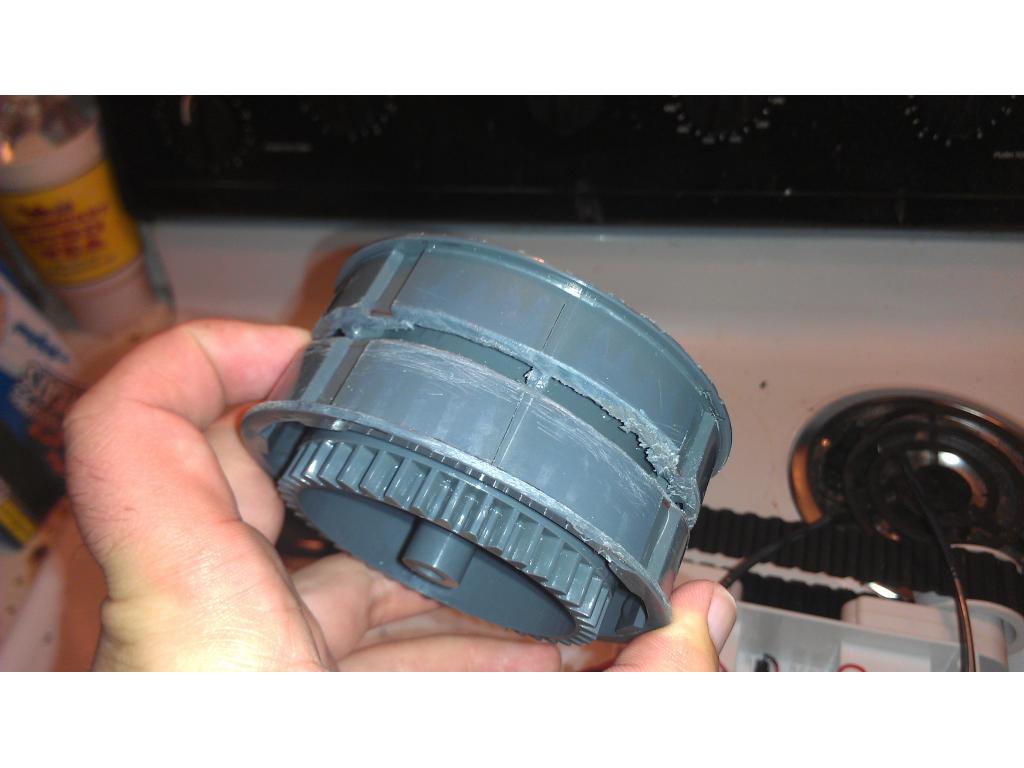
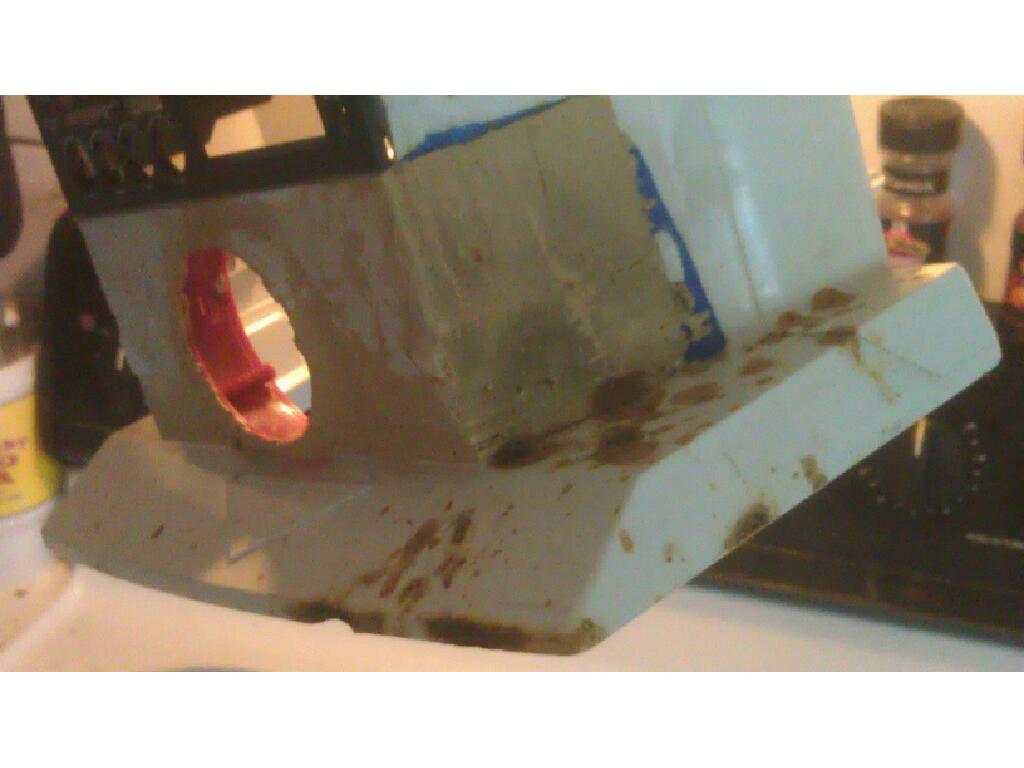
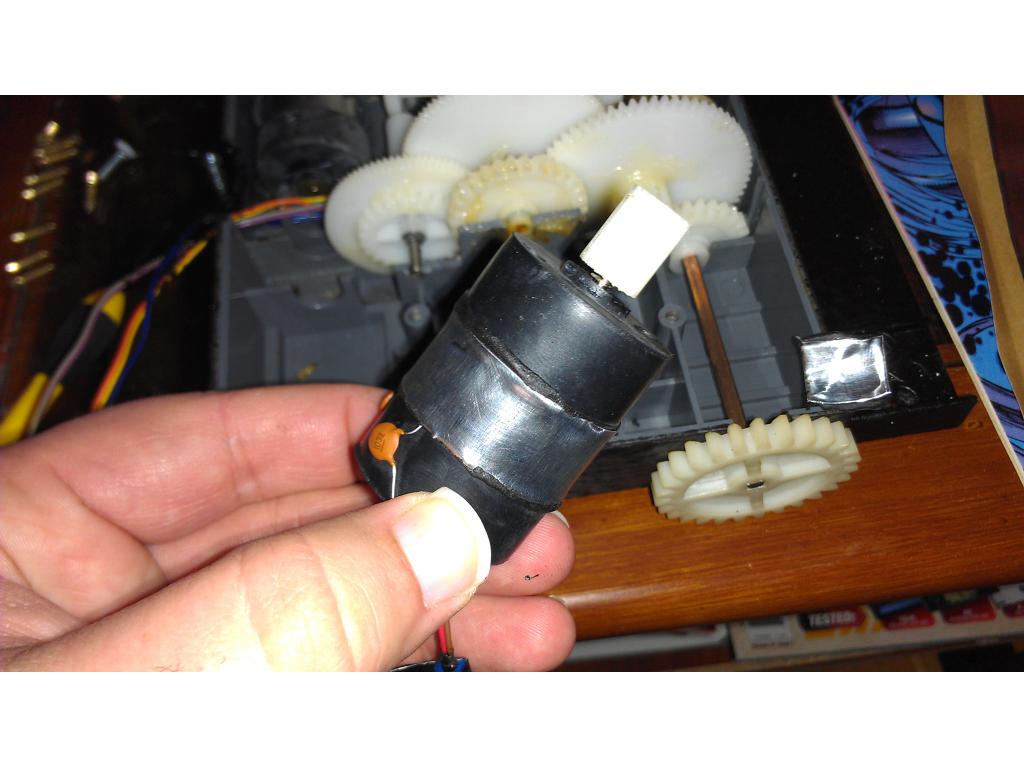
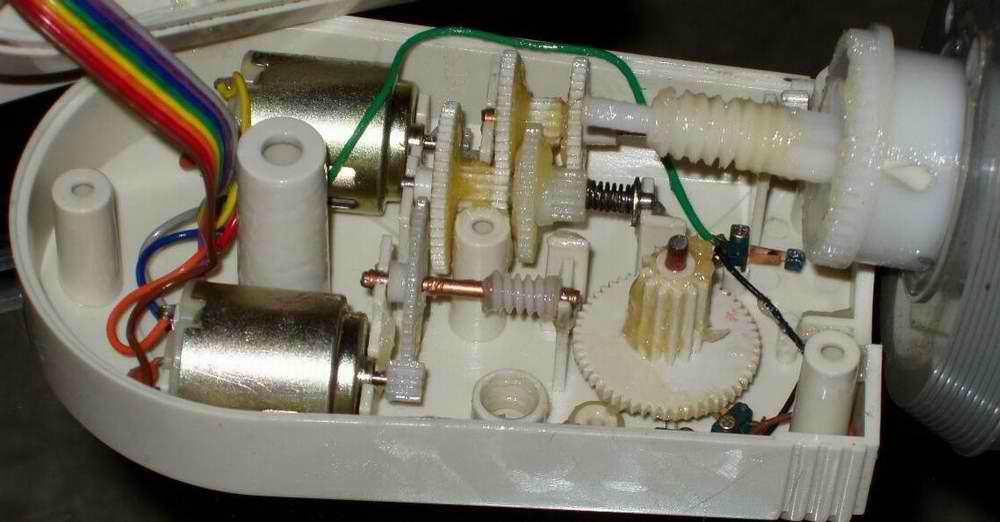
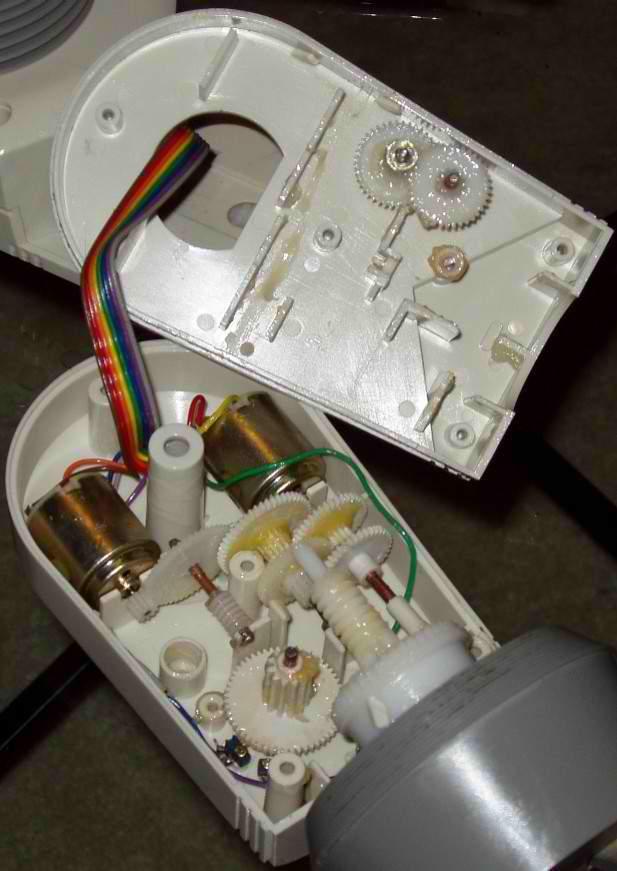
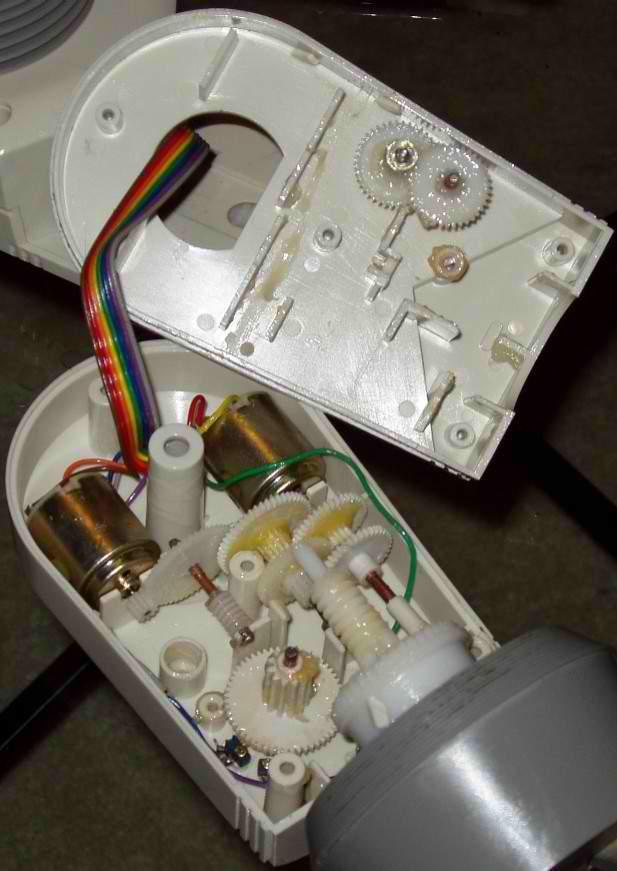
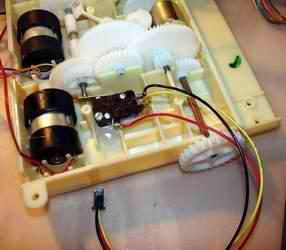
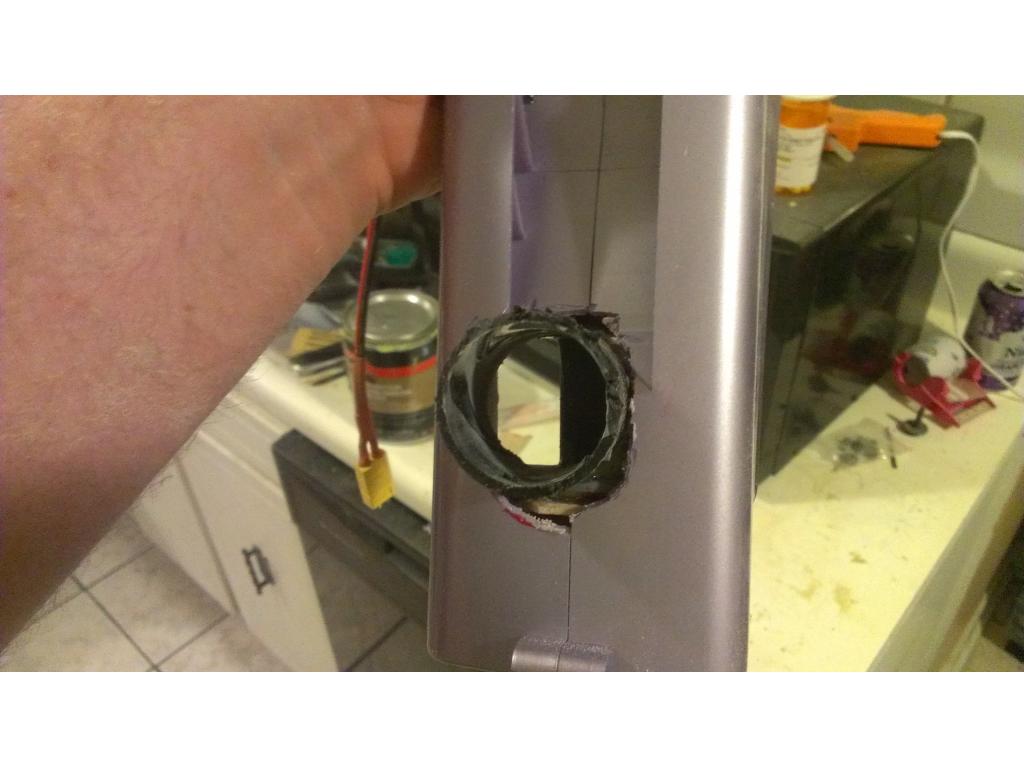
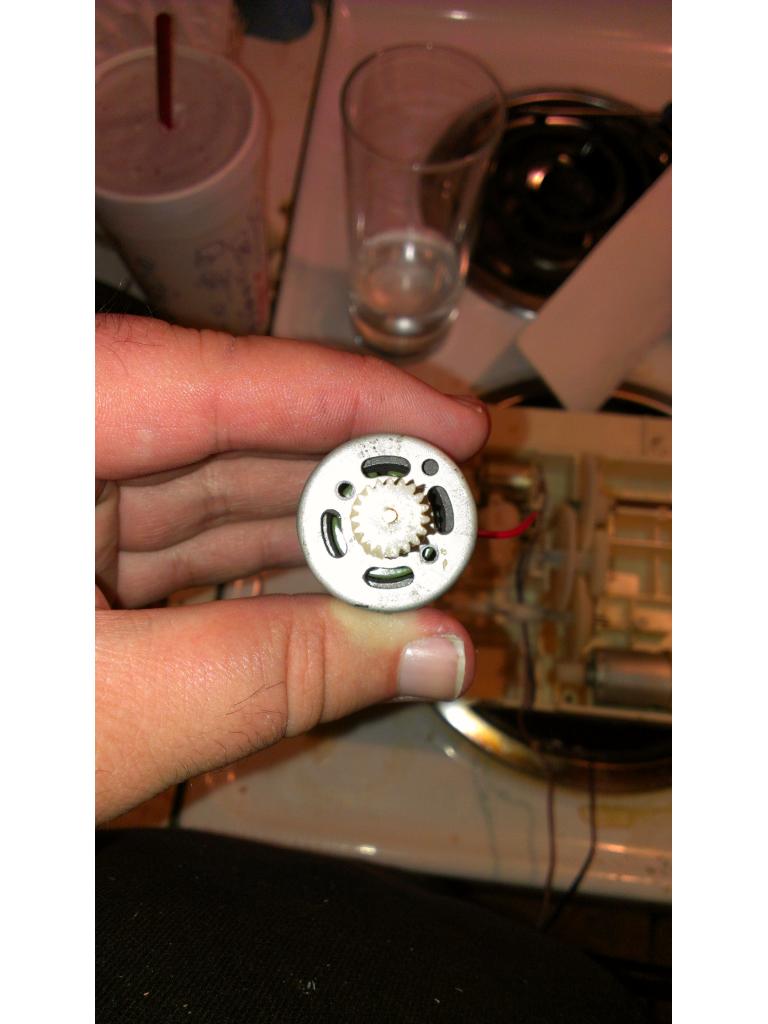
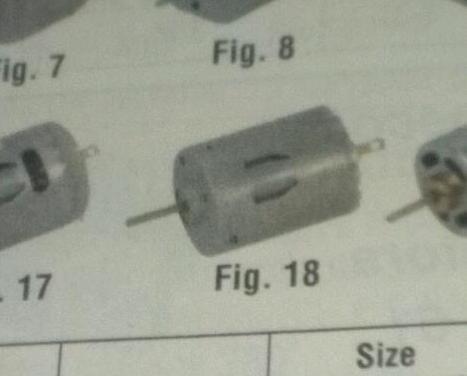
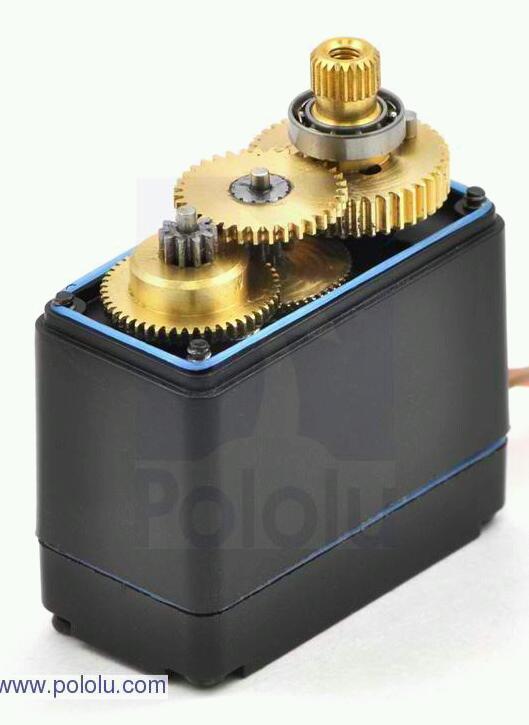
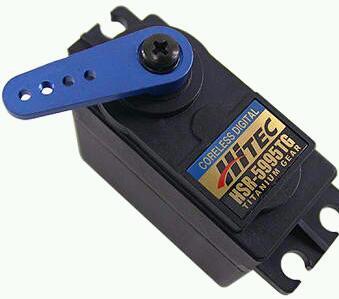
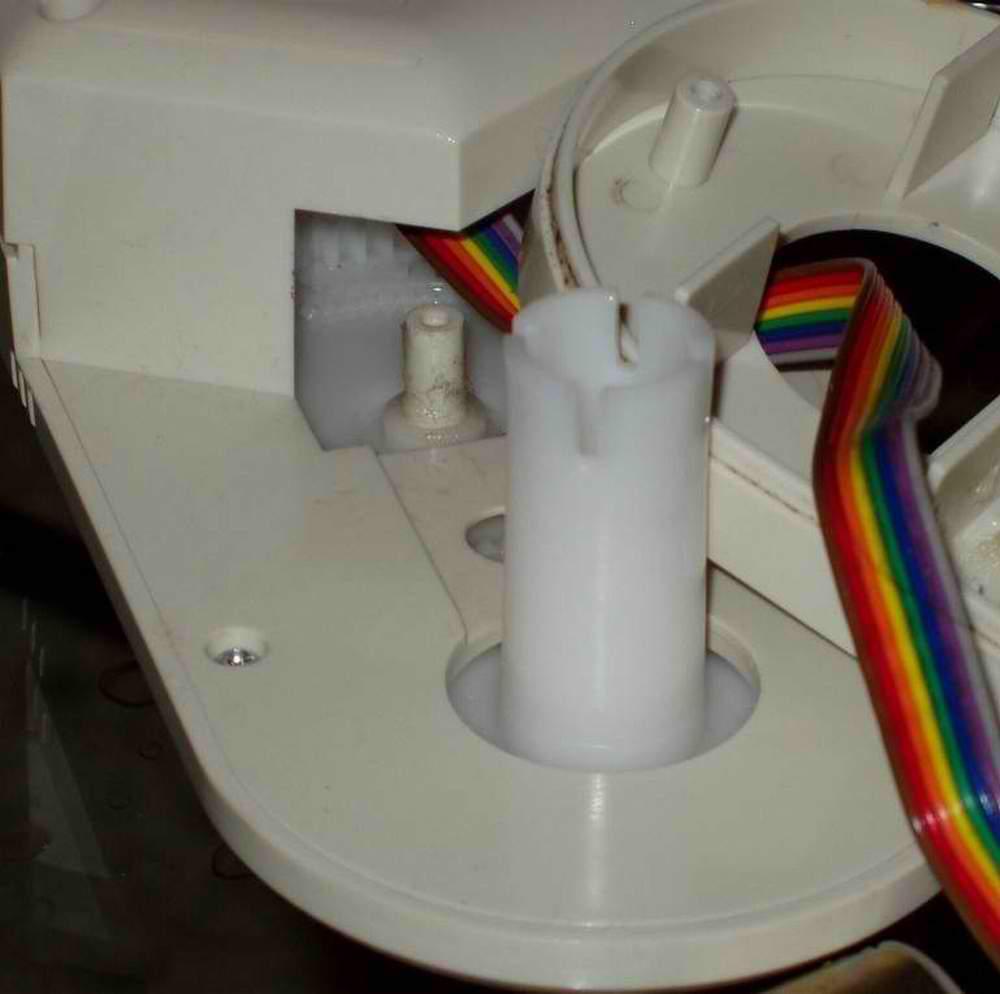
Geartrain modding - robotmaker sent me two motors that.have more torque than my stock ones , if I could get ahold of a second gearbox for a 2000 I could do a "quad motor" drive I just need the extra gears. I'm confident that I can upgrade it to smoothly move my heavy bot.
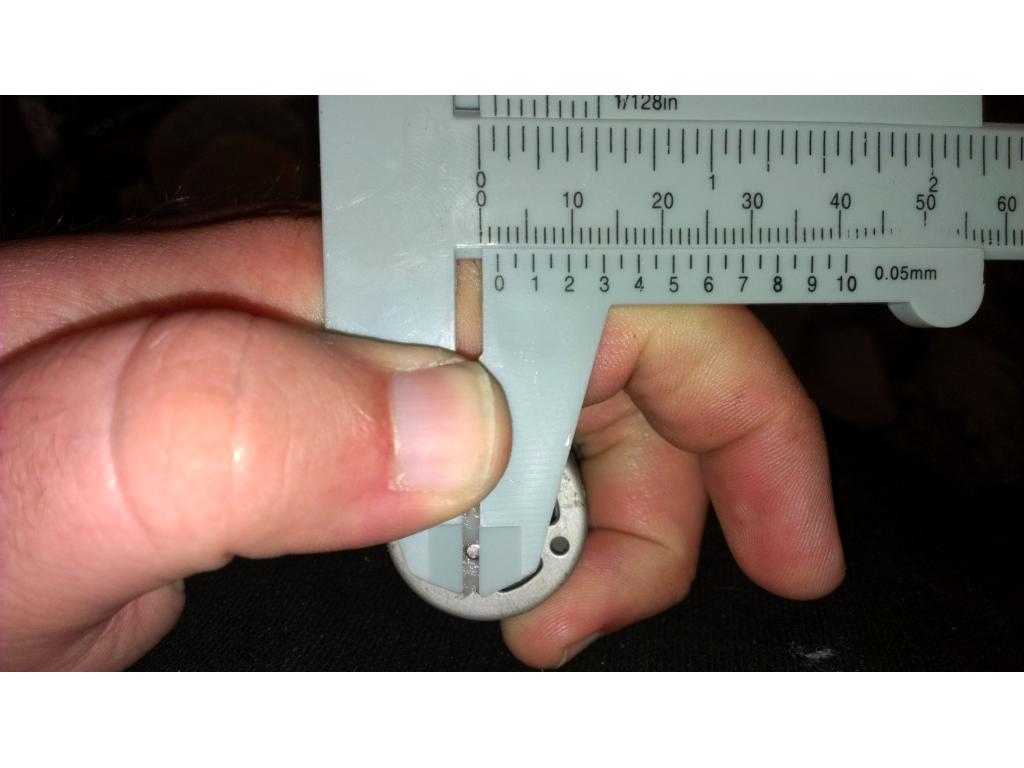
For the most.part the motors can fit with some small modifications but I really need to see if I can get ahold of at least 2 more opinions that go on the motors so I can do quad motor setup , that would split the torque between two motors and I believe would easily move my 60 pound bot around.