cE9s4PsOgeBQIORwjd5!~~60_1-634818020230156250.jpg)
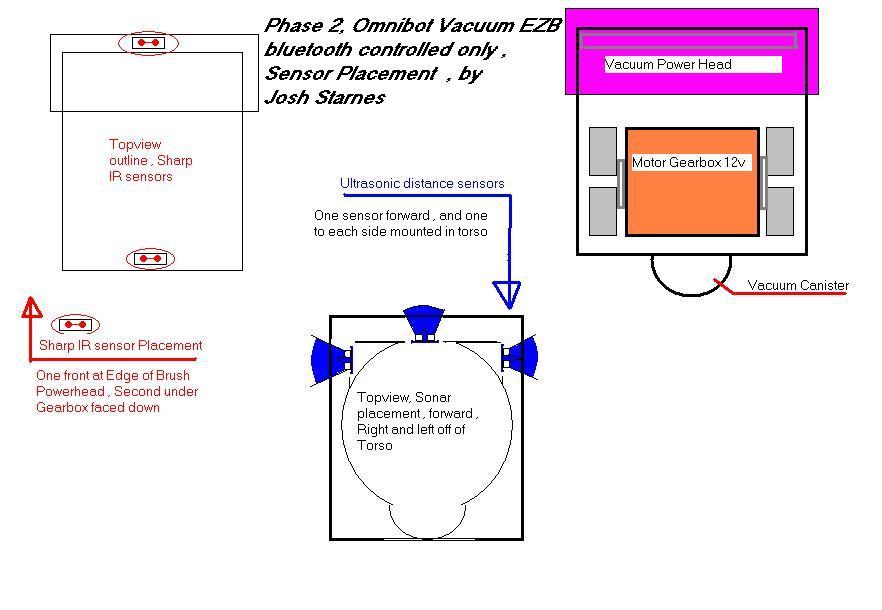
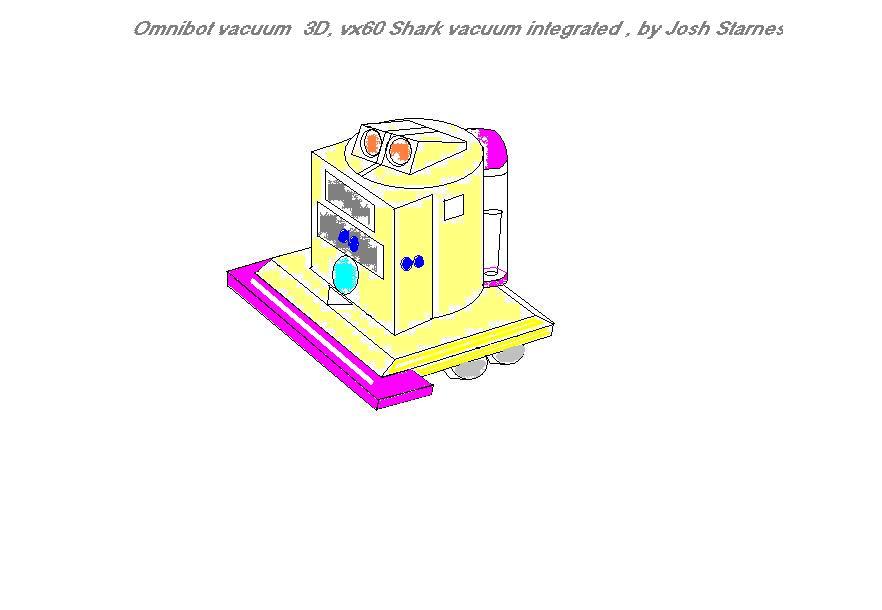
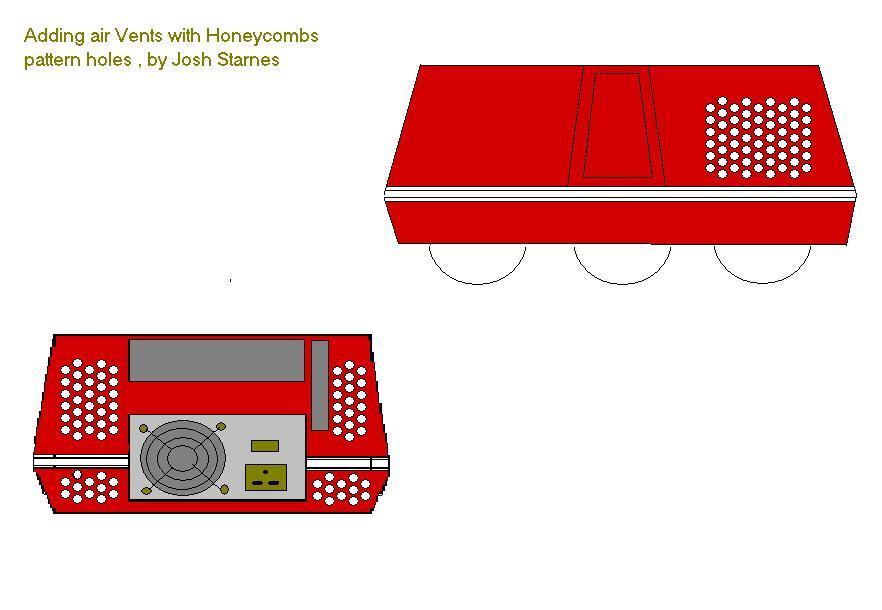
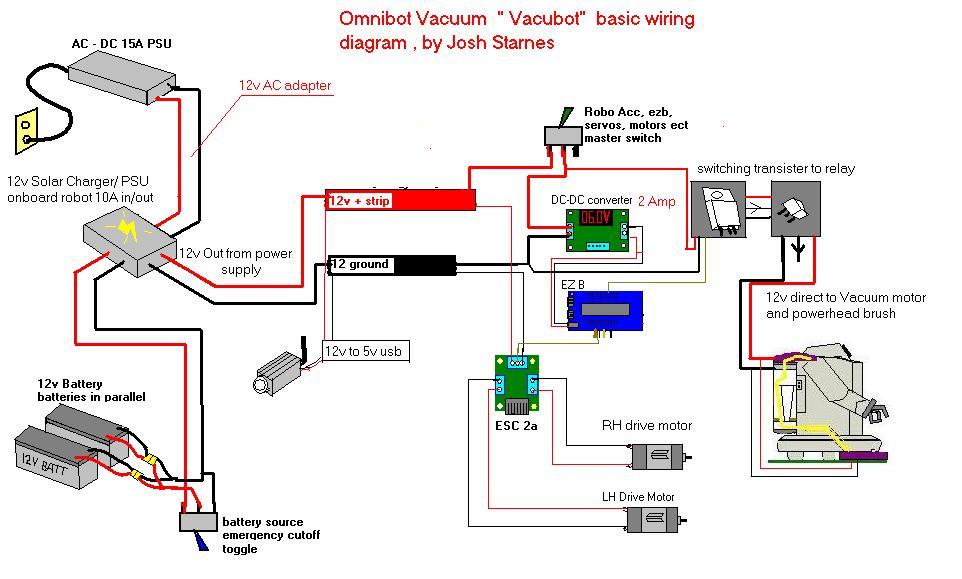
Lupuc4g~~60_35-634706297915000000.jpg)
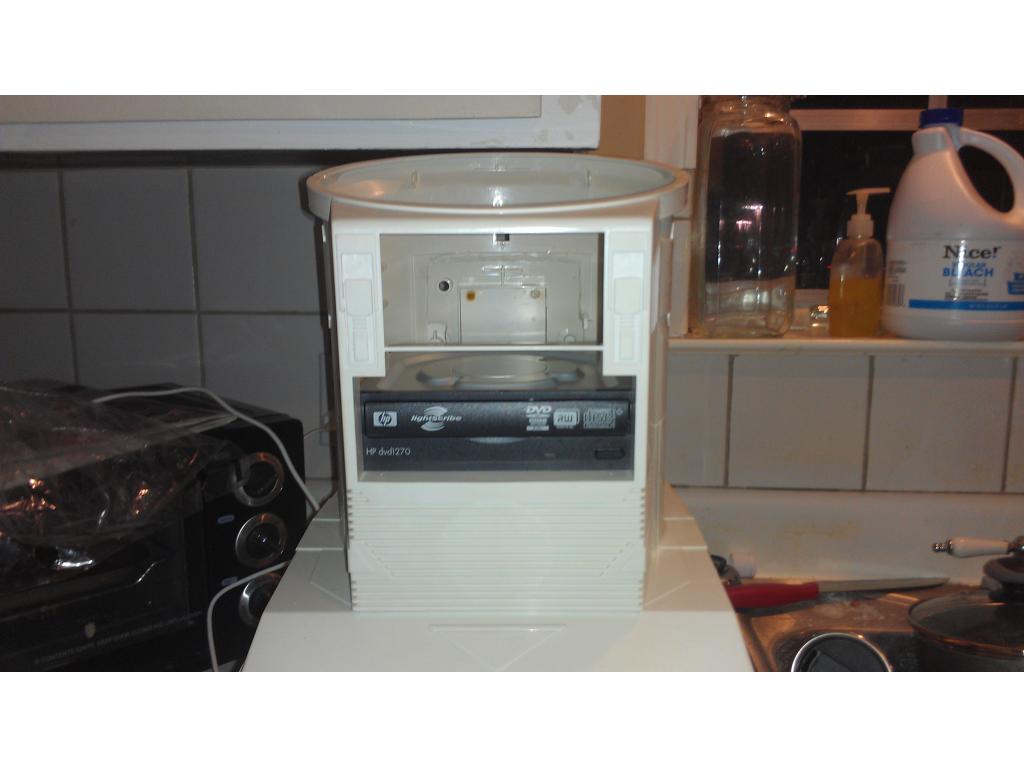
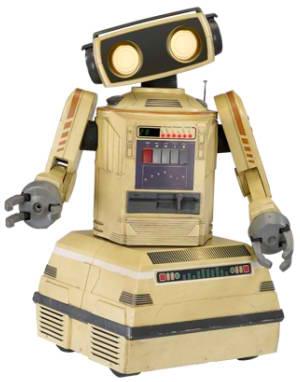
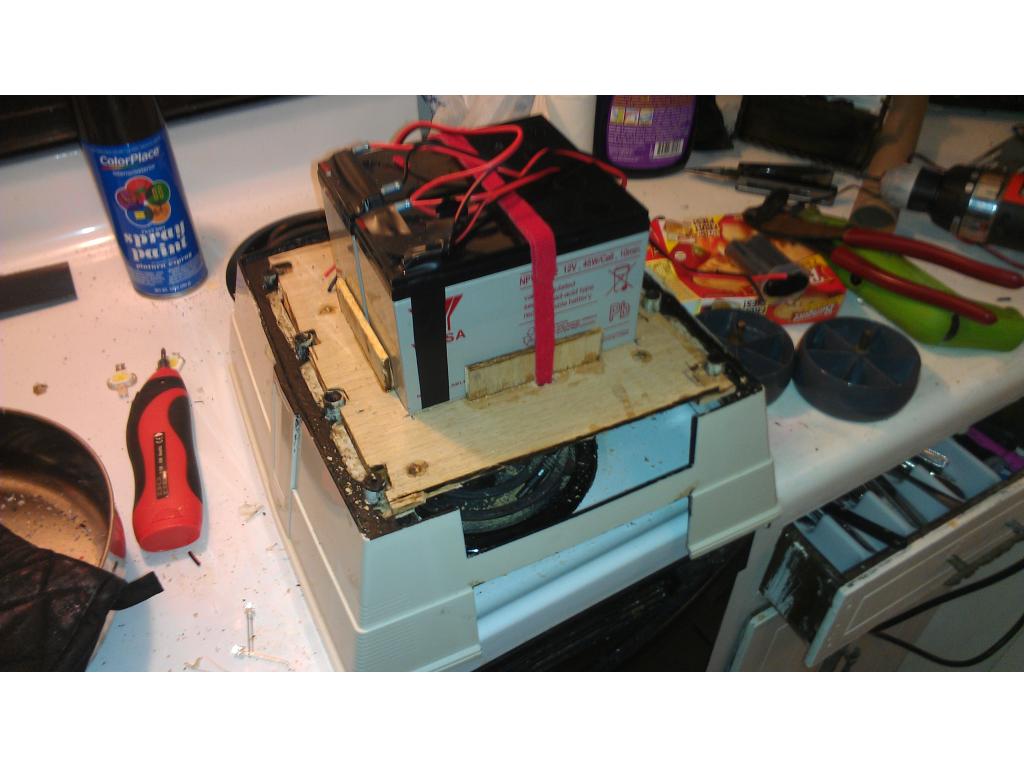
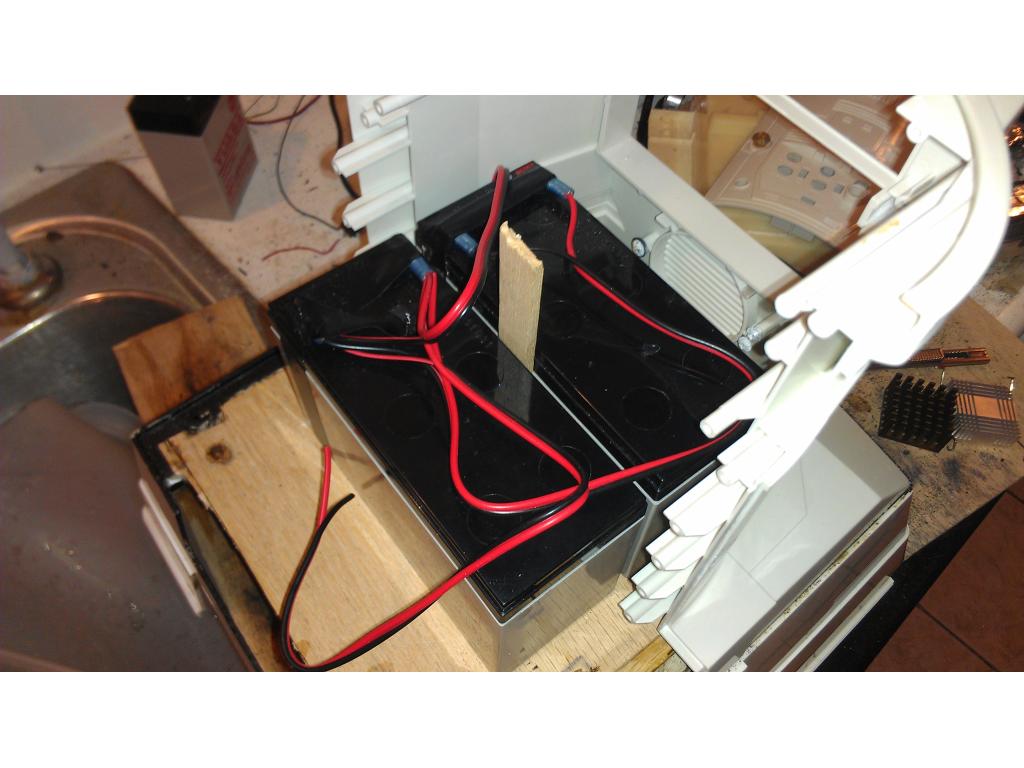
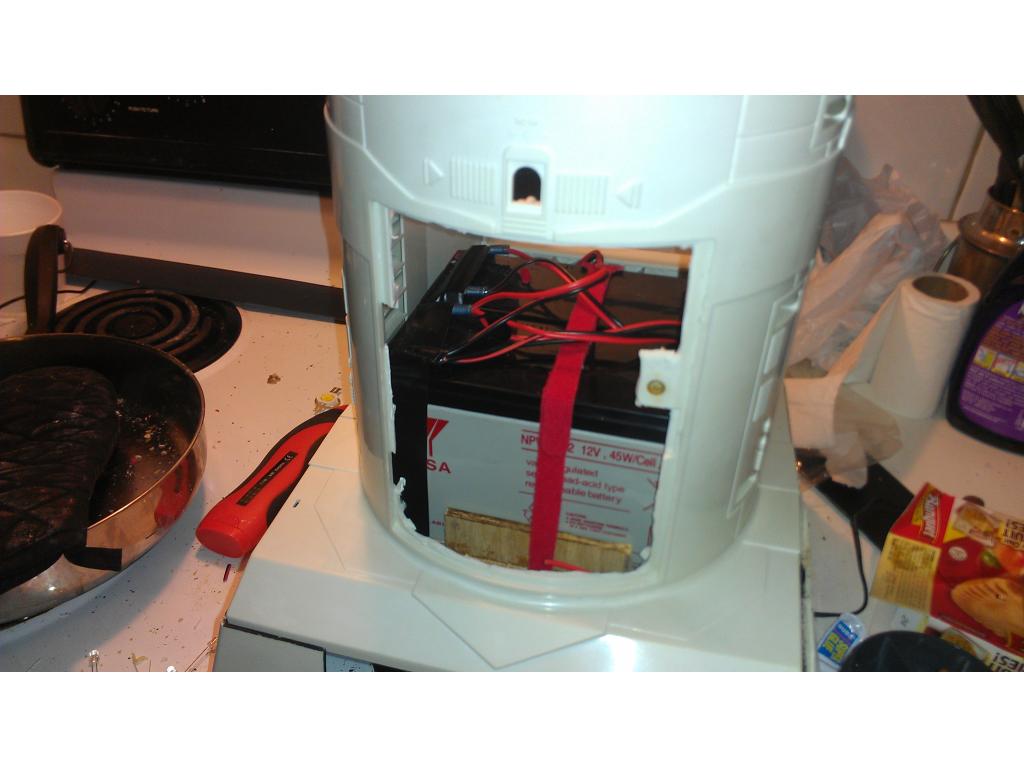
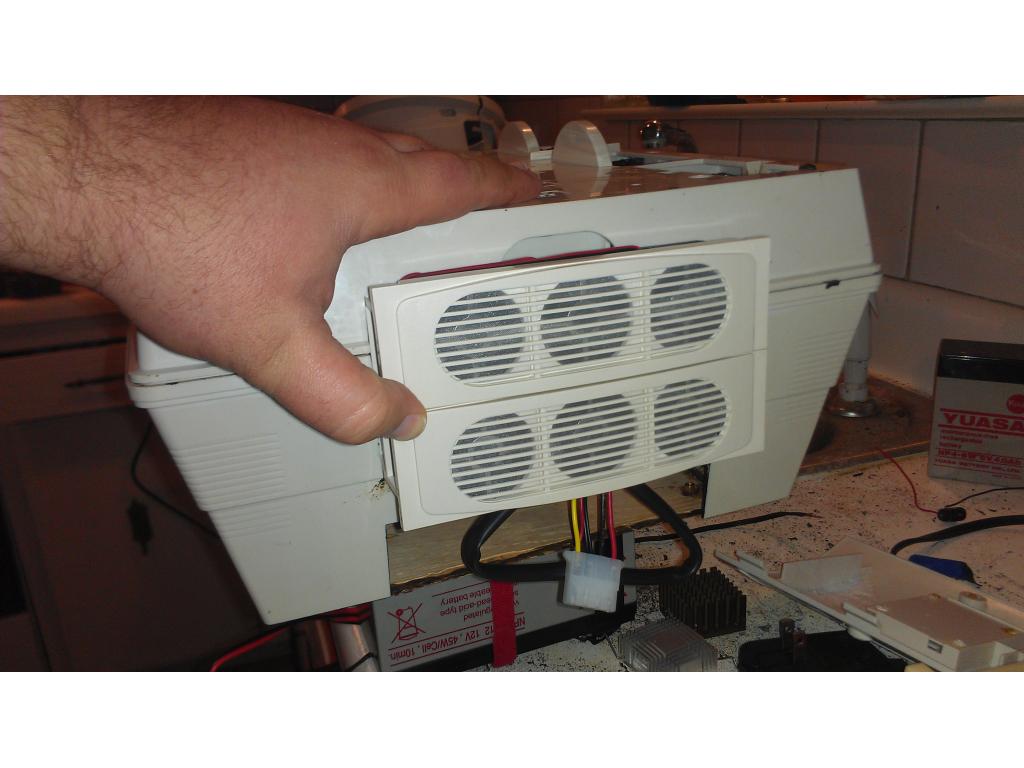
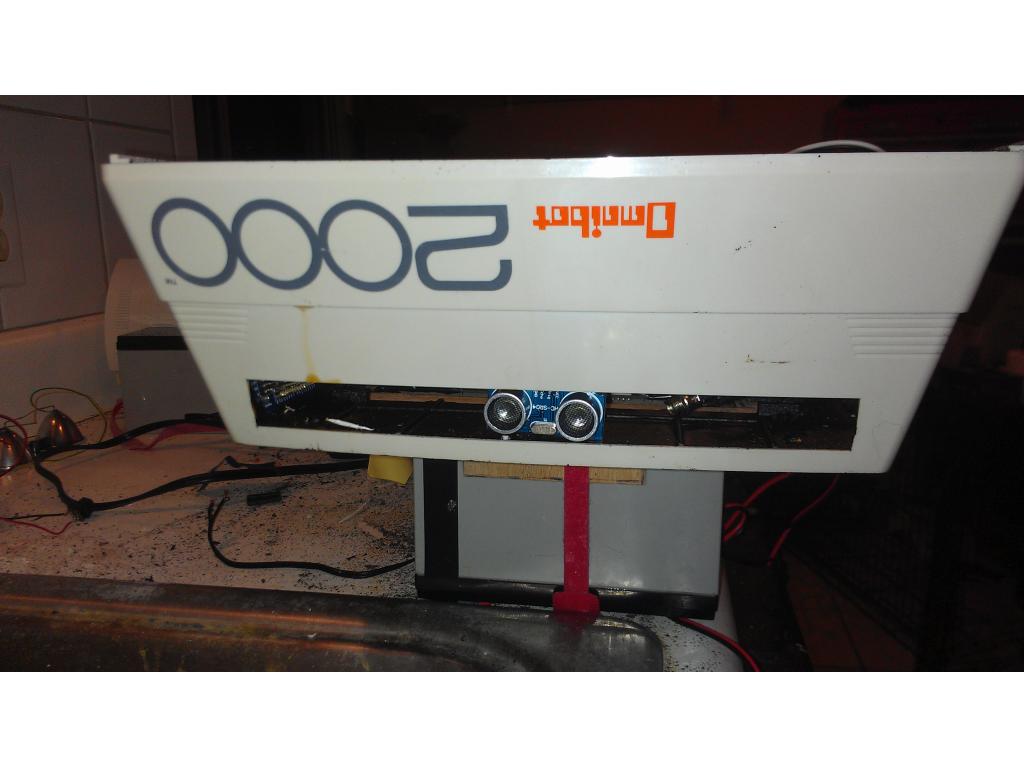
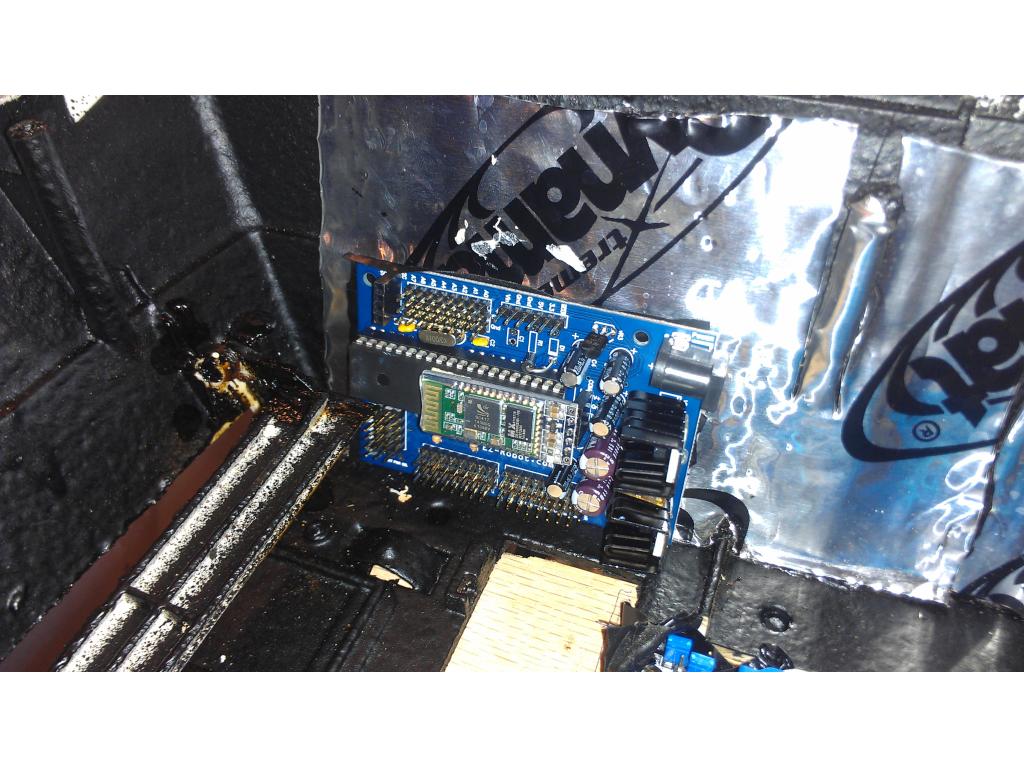
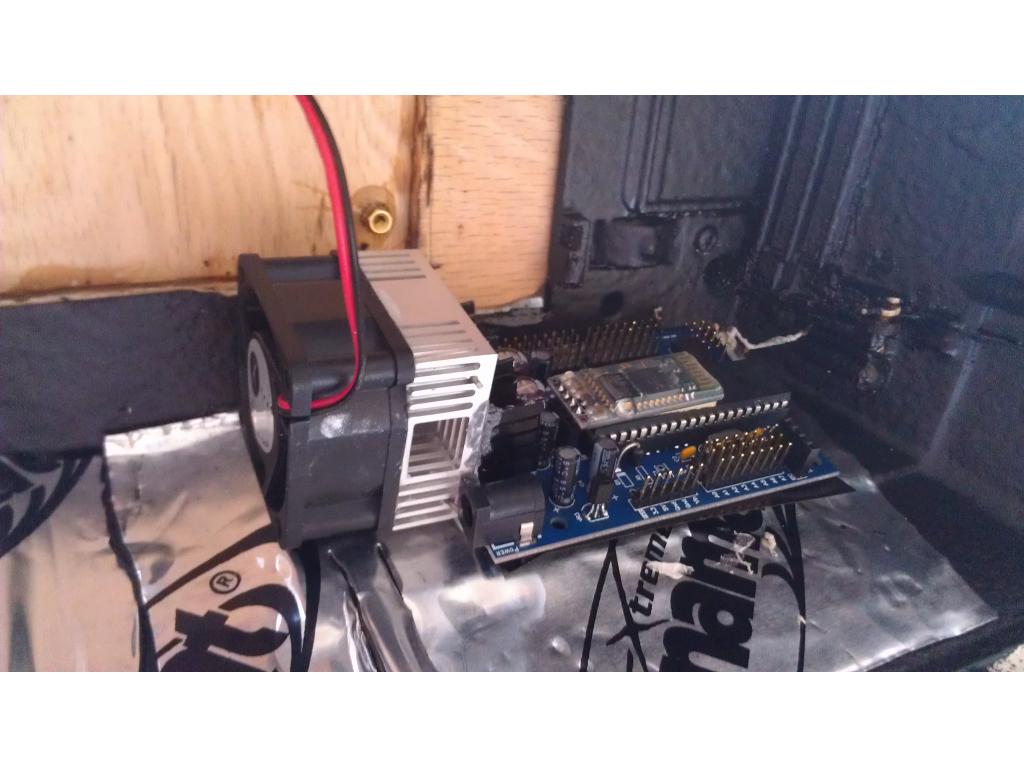
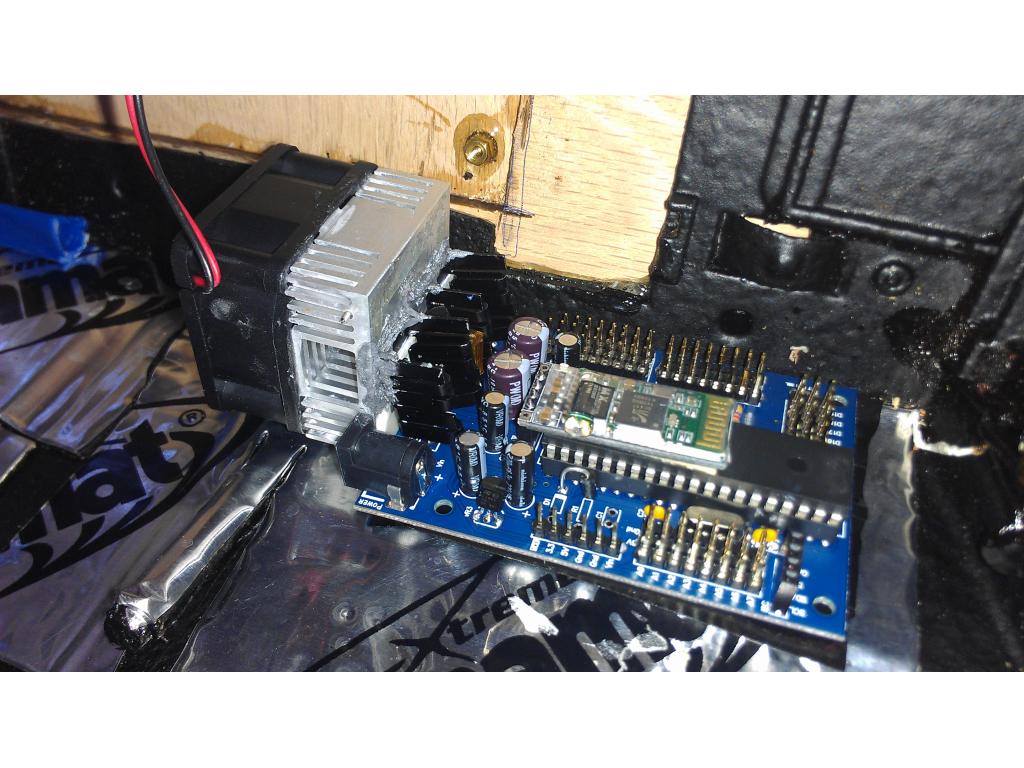
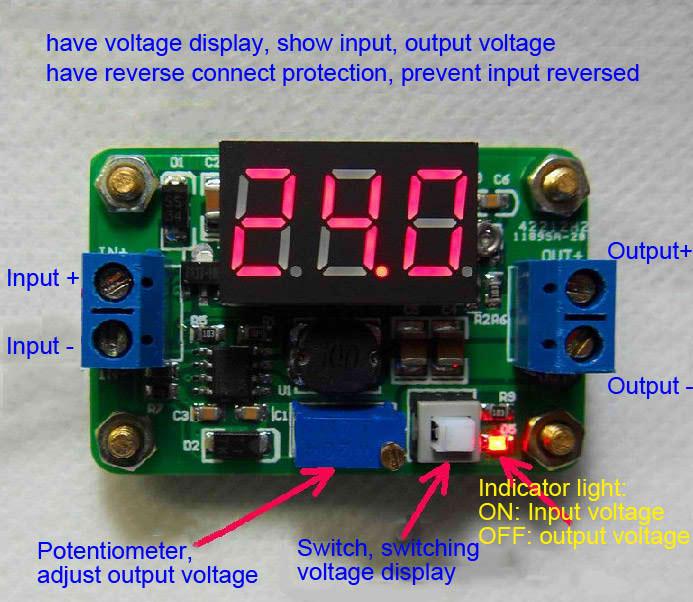
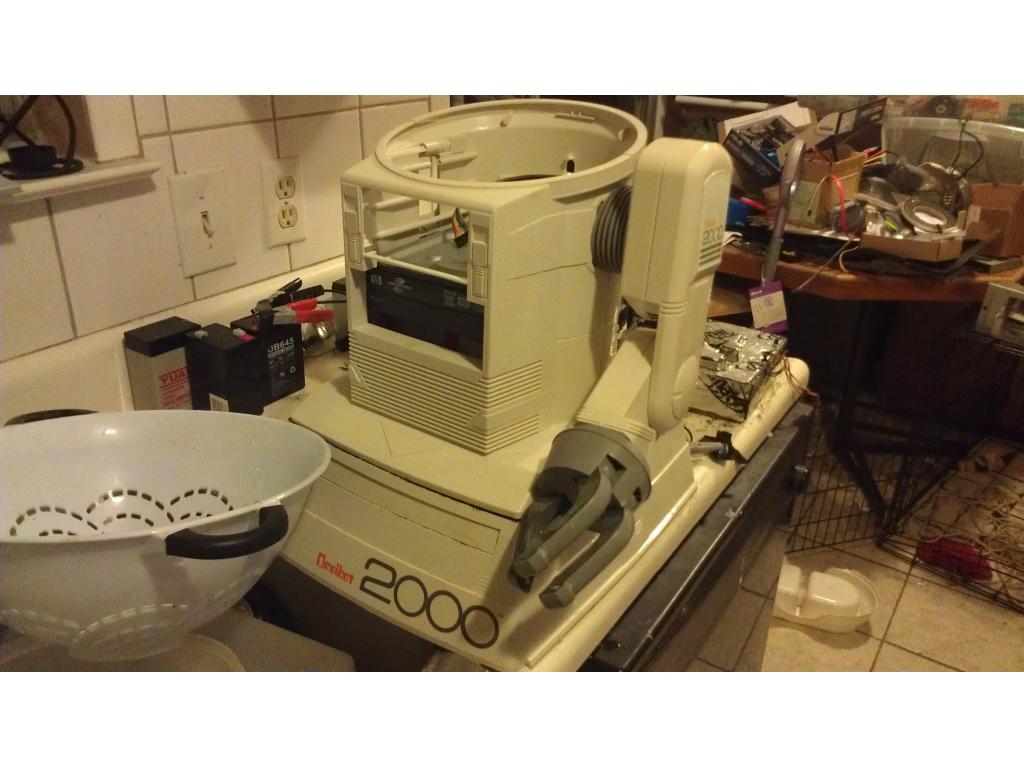
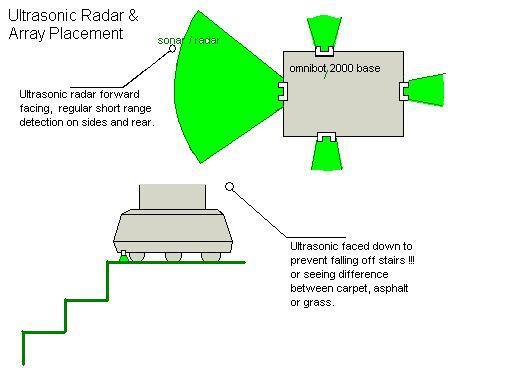
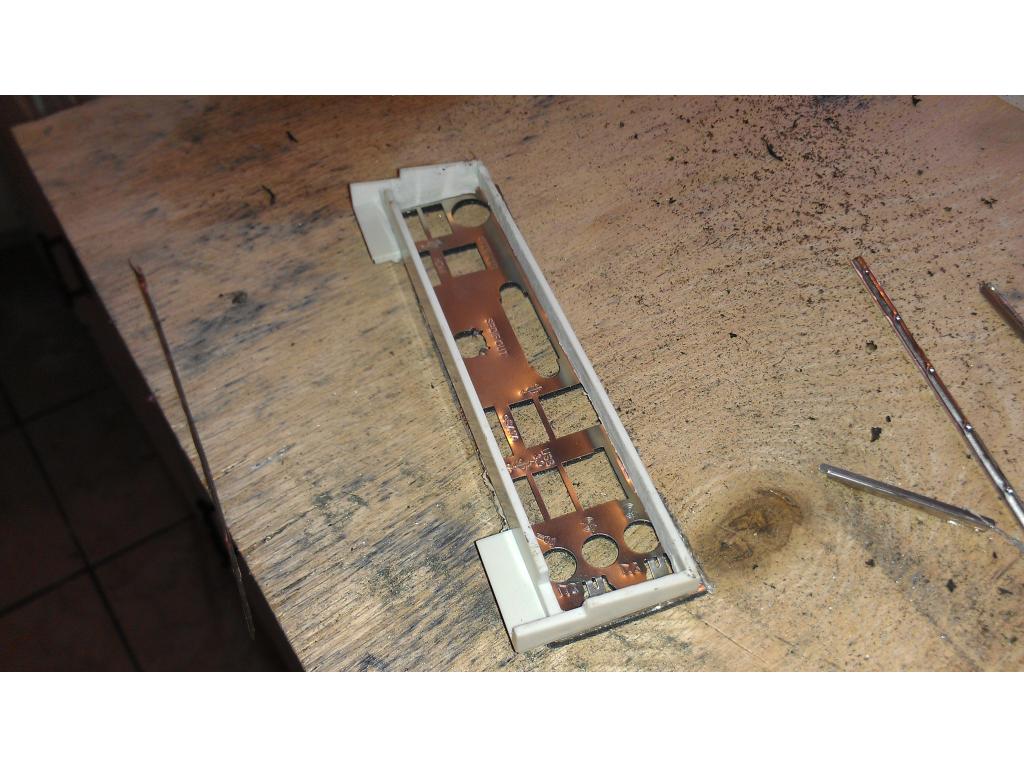
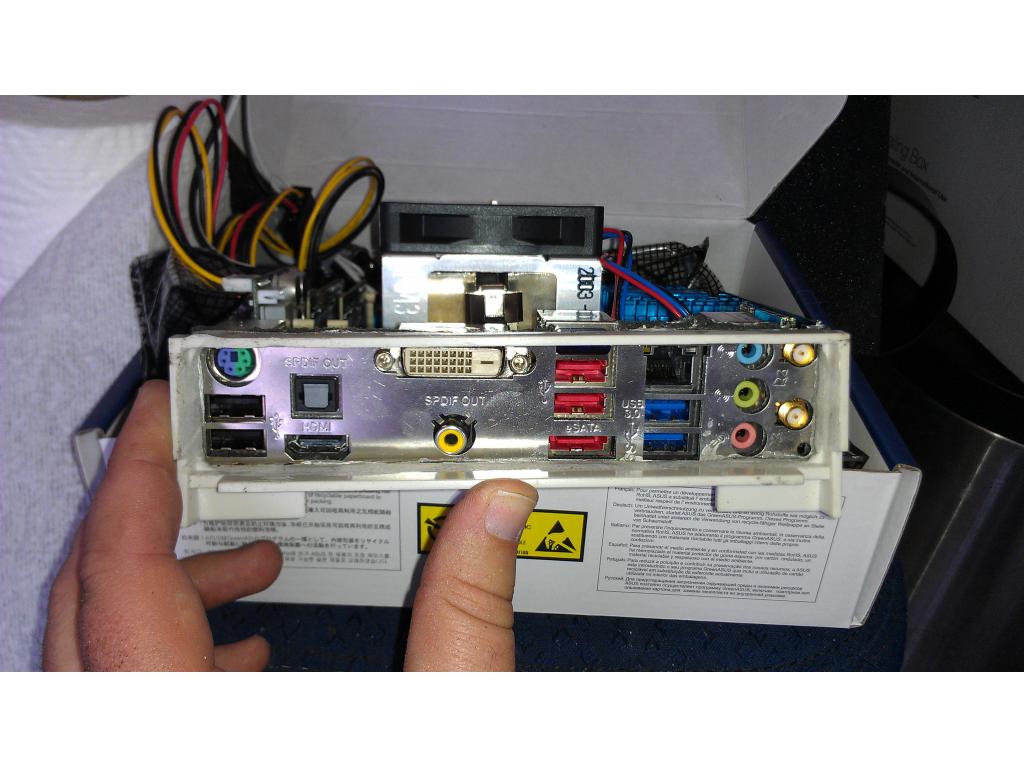
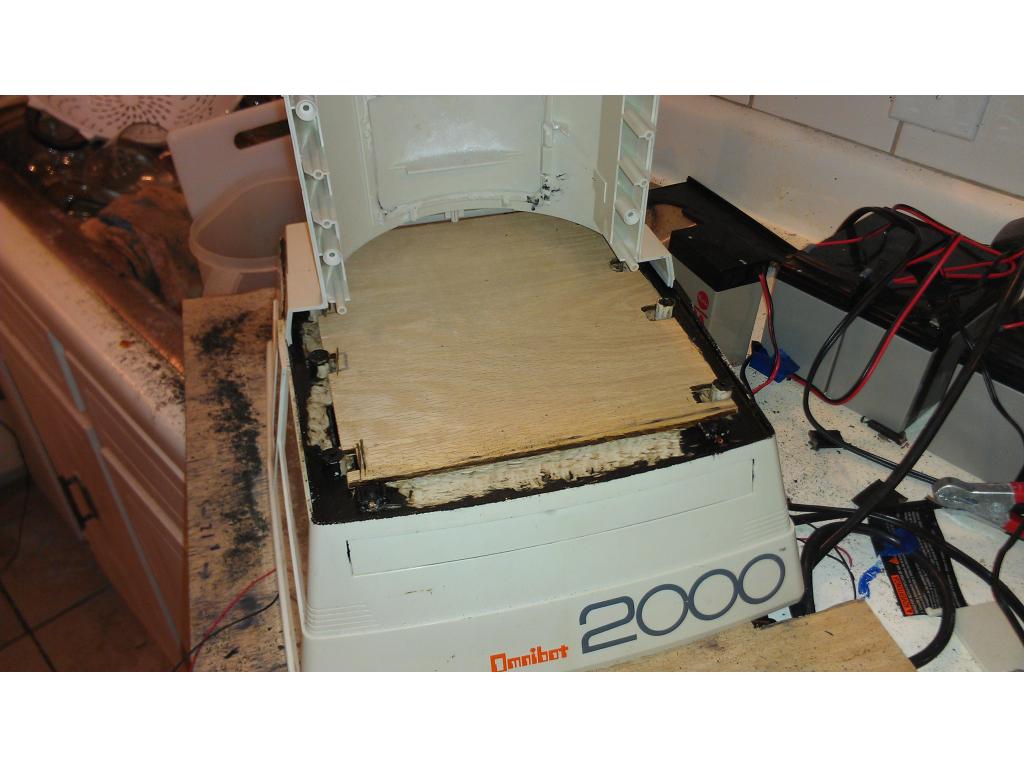
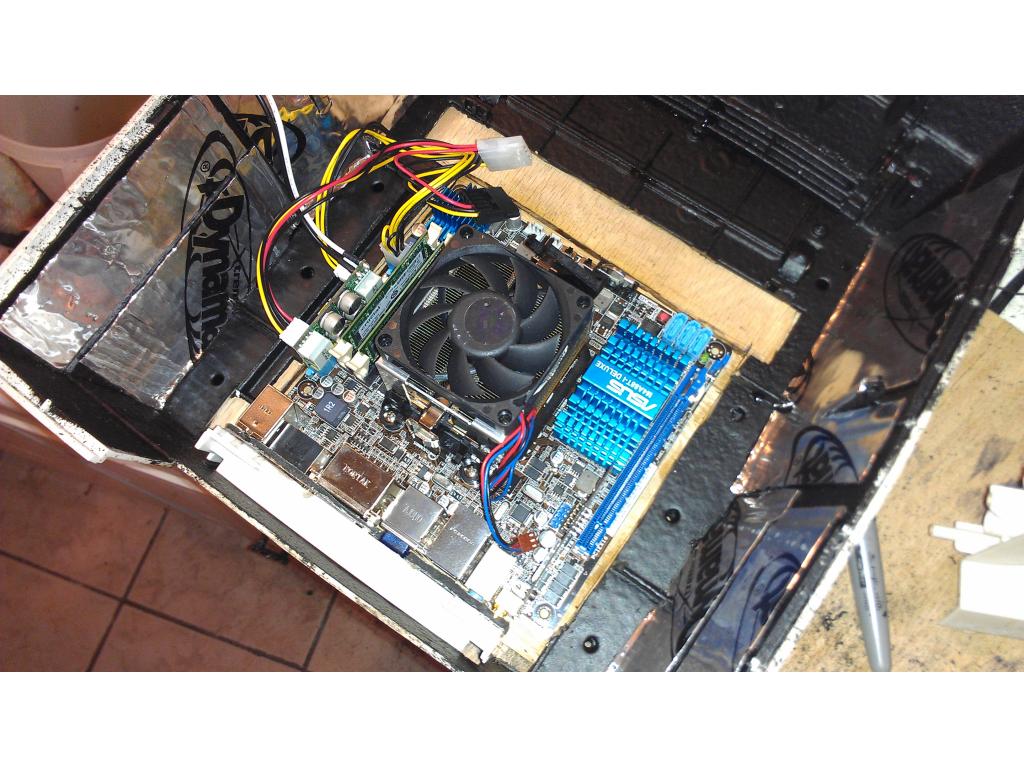
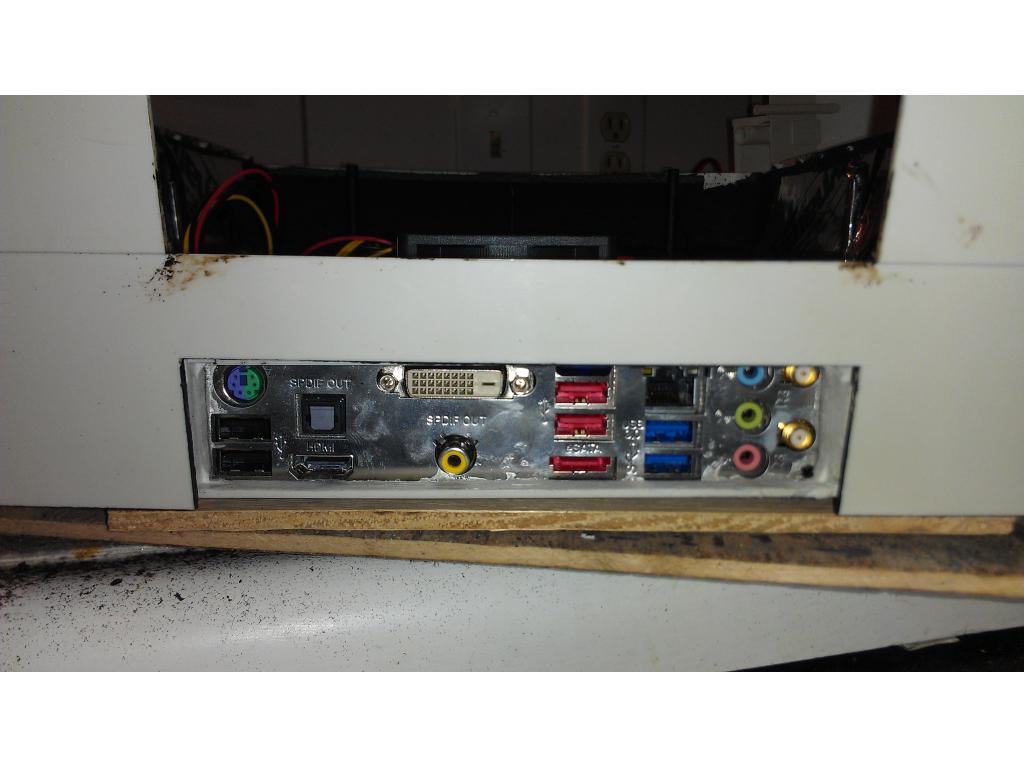
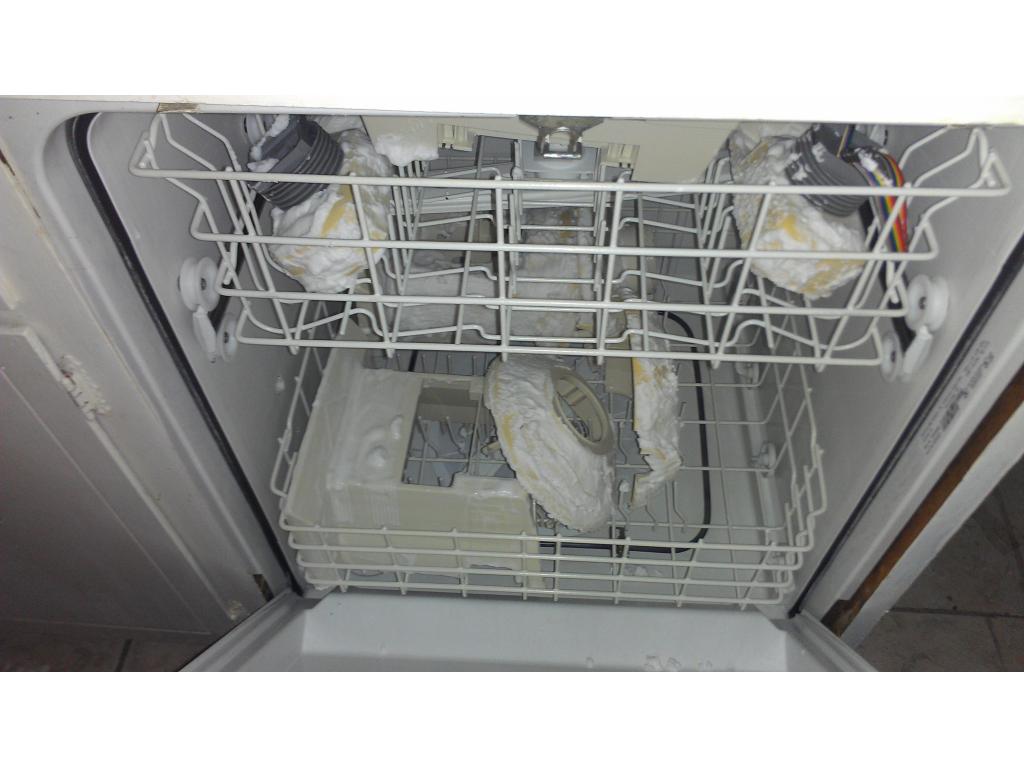
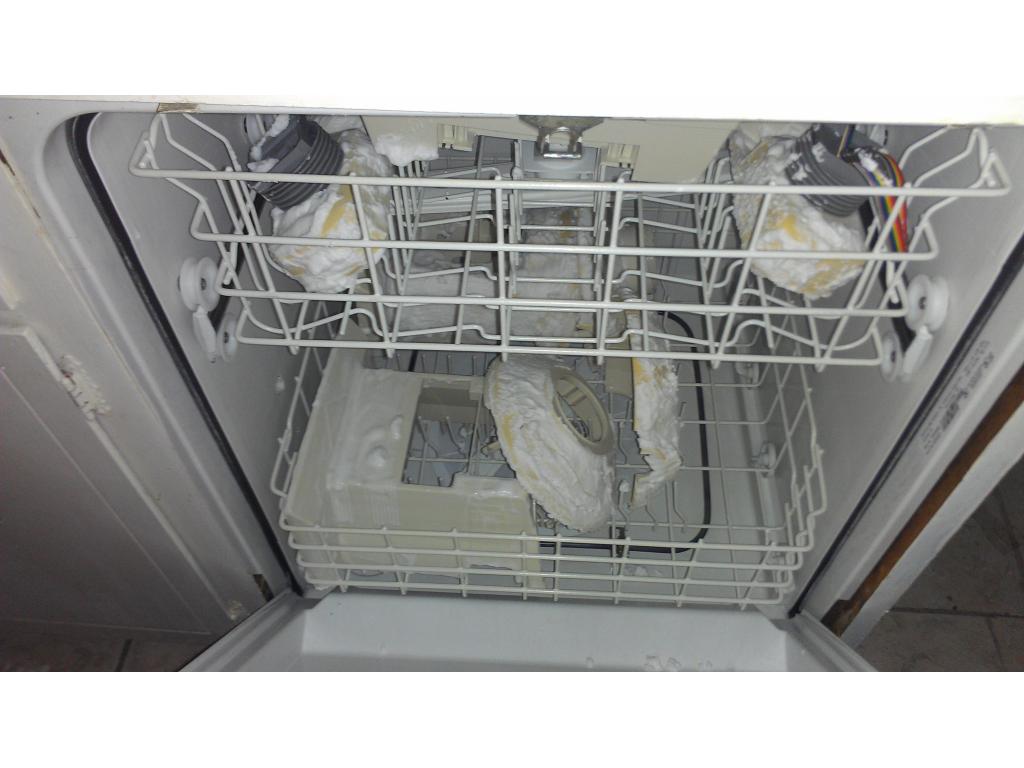
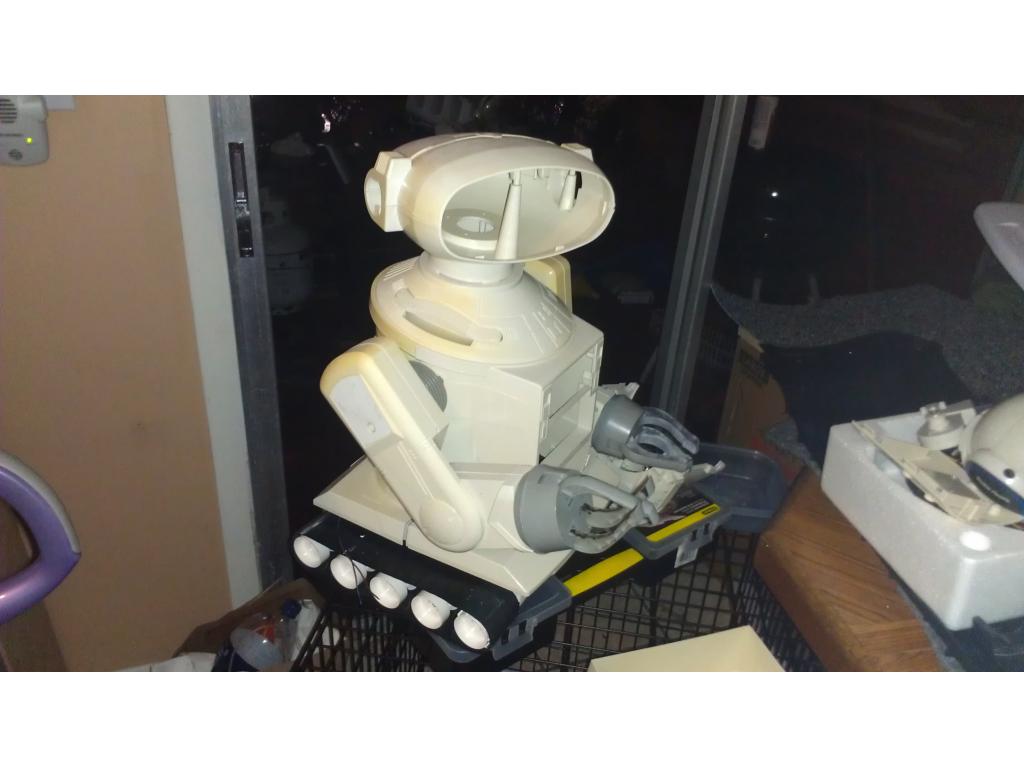
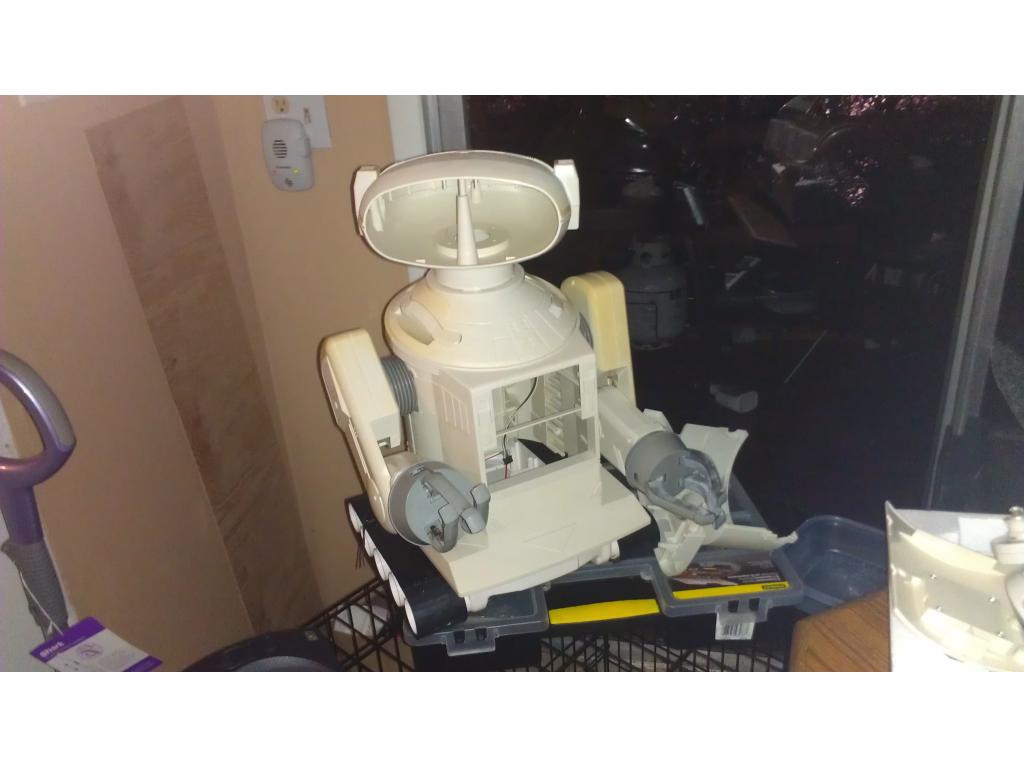
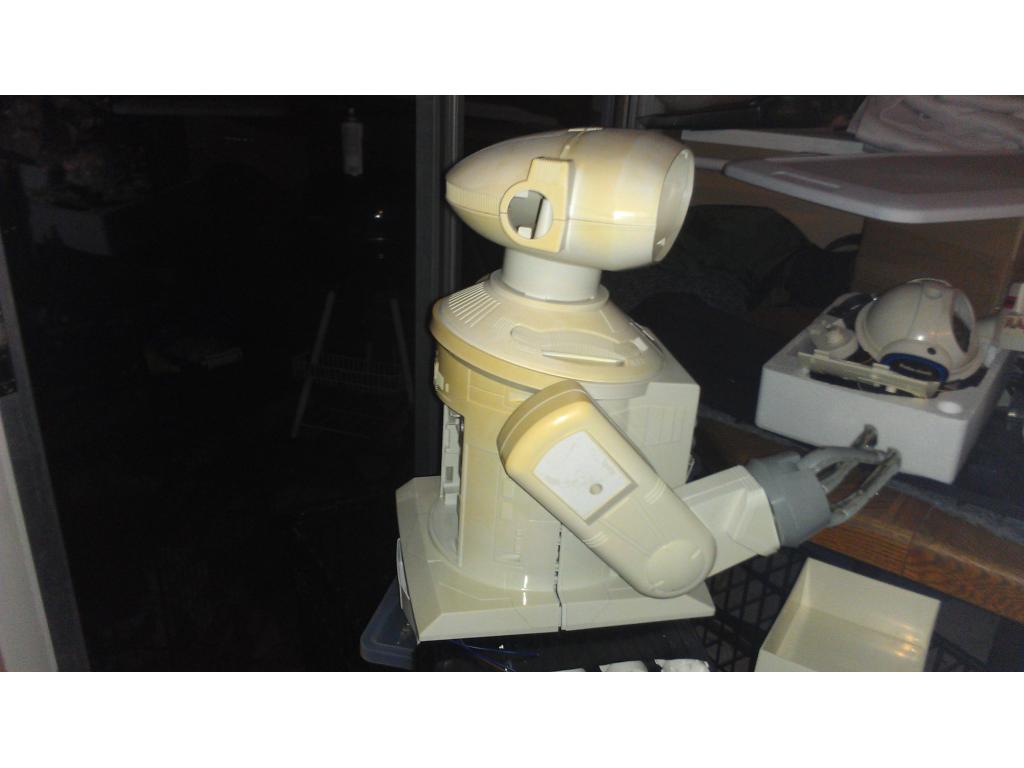
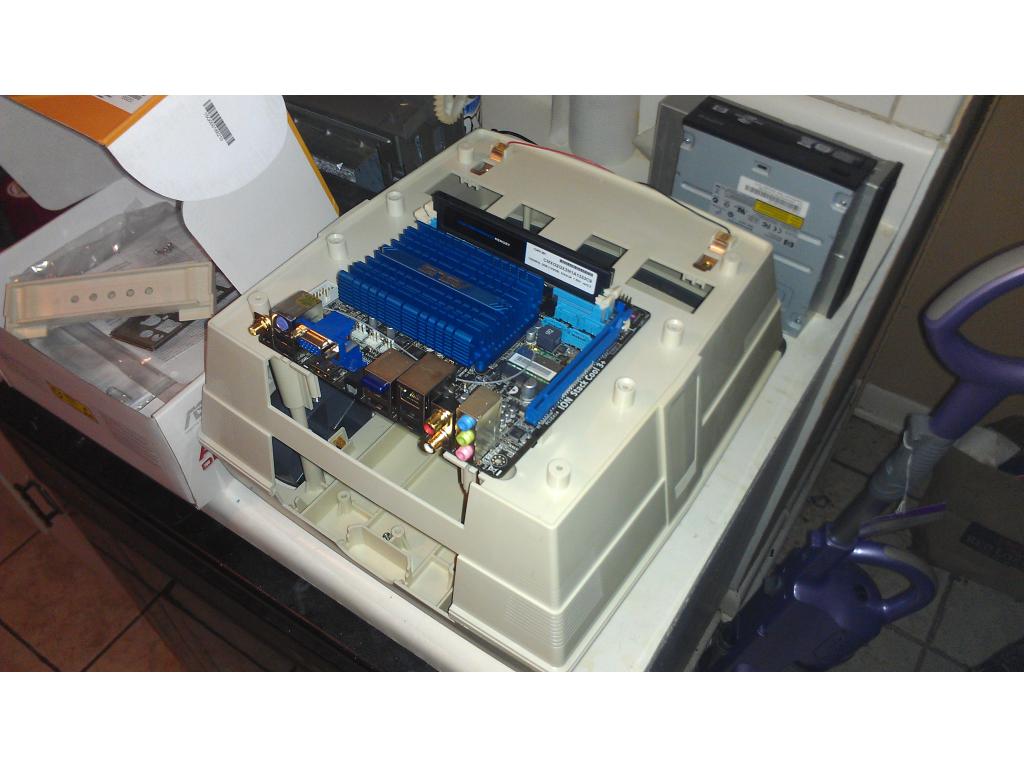
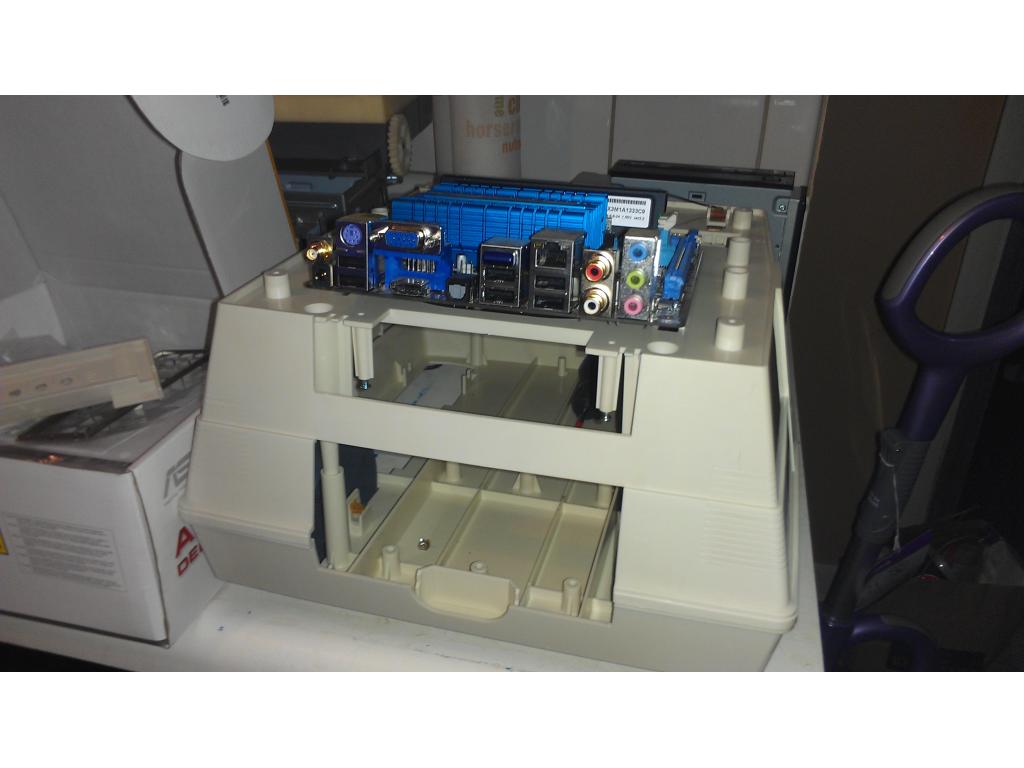
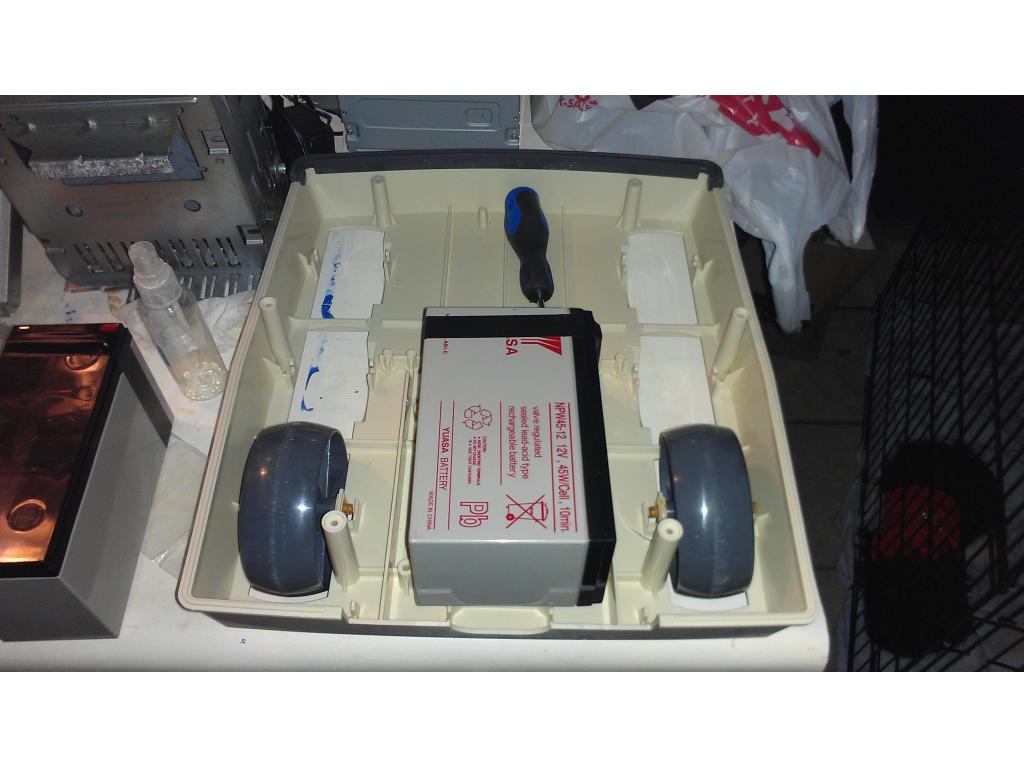
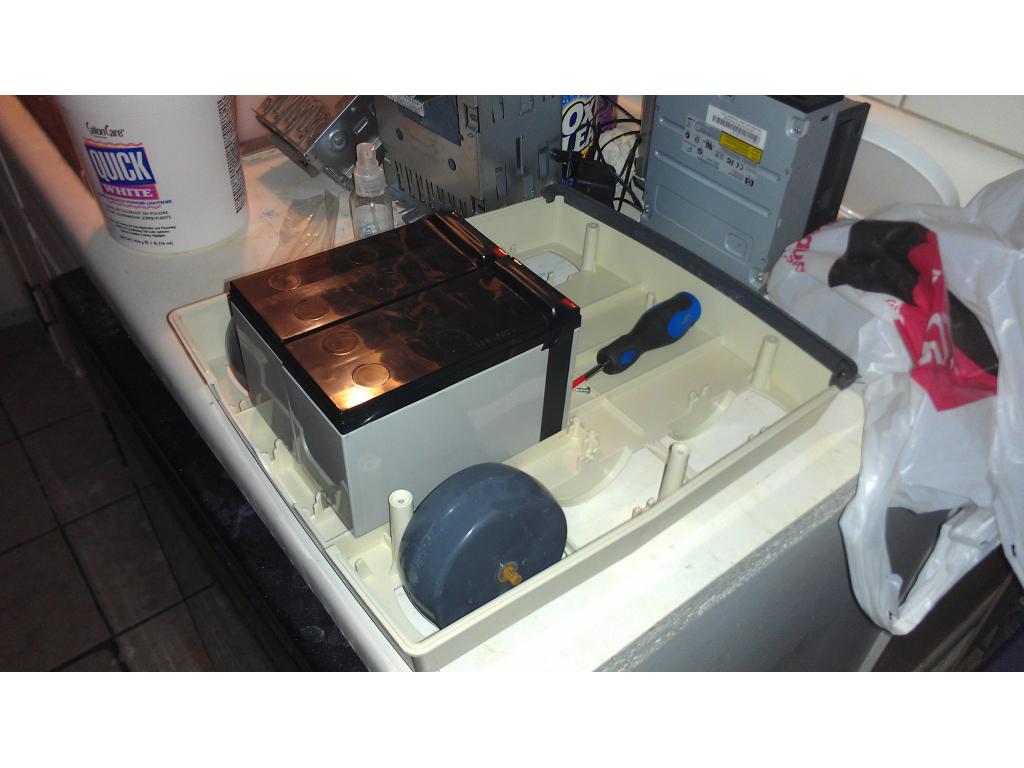
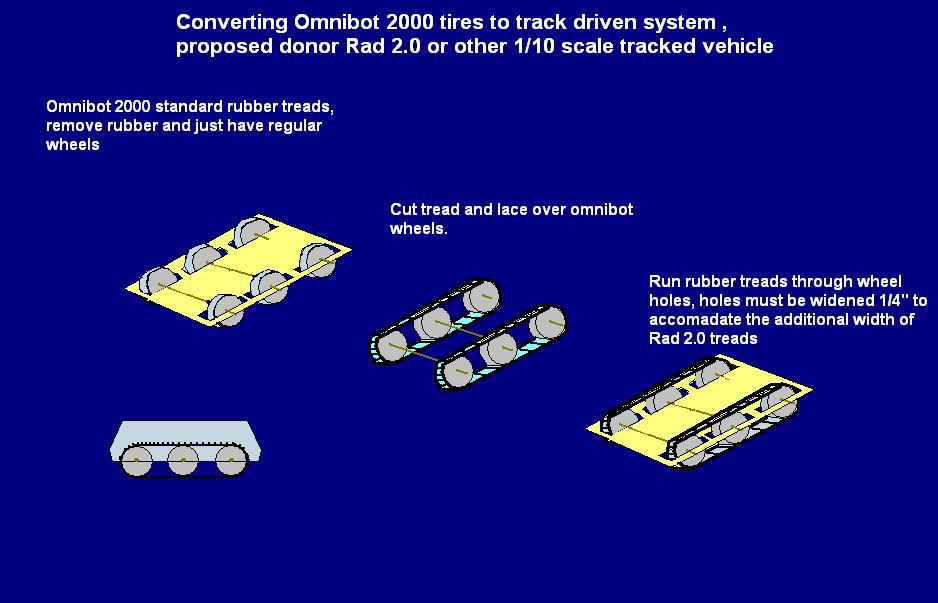


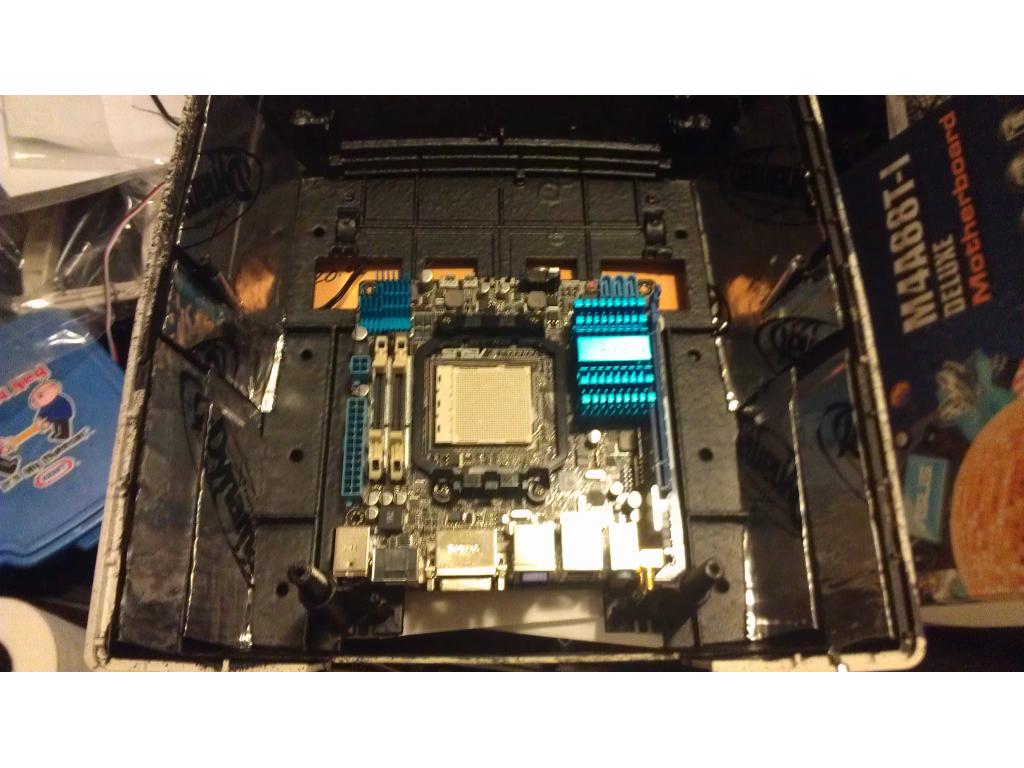
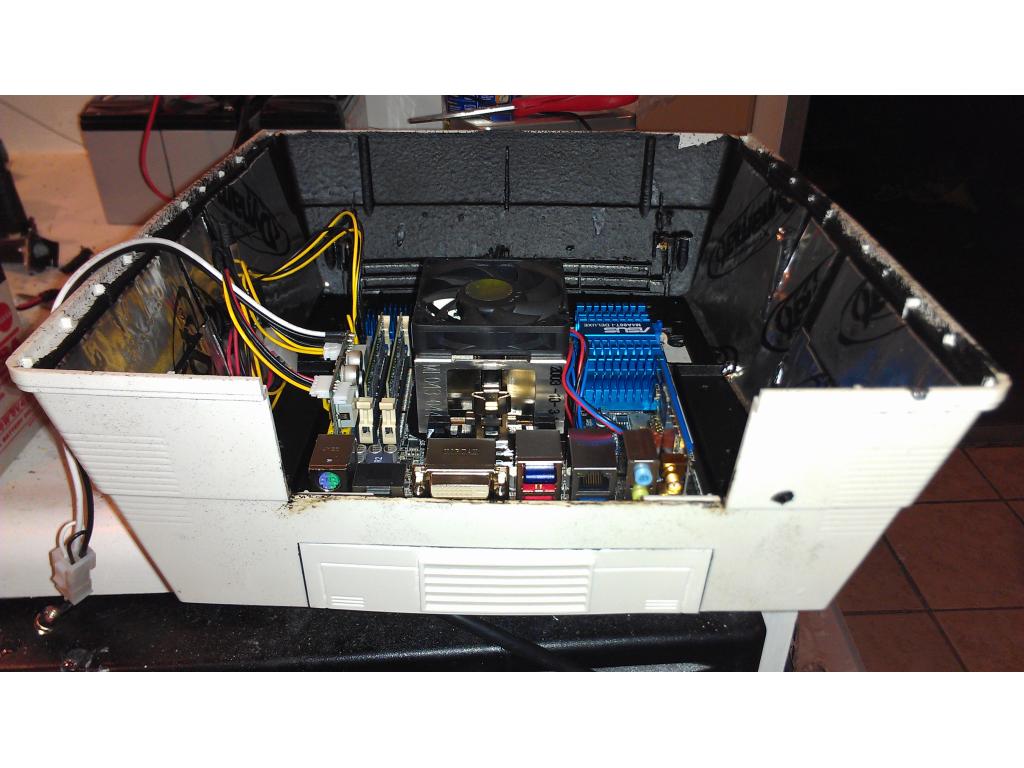
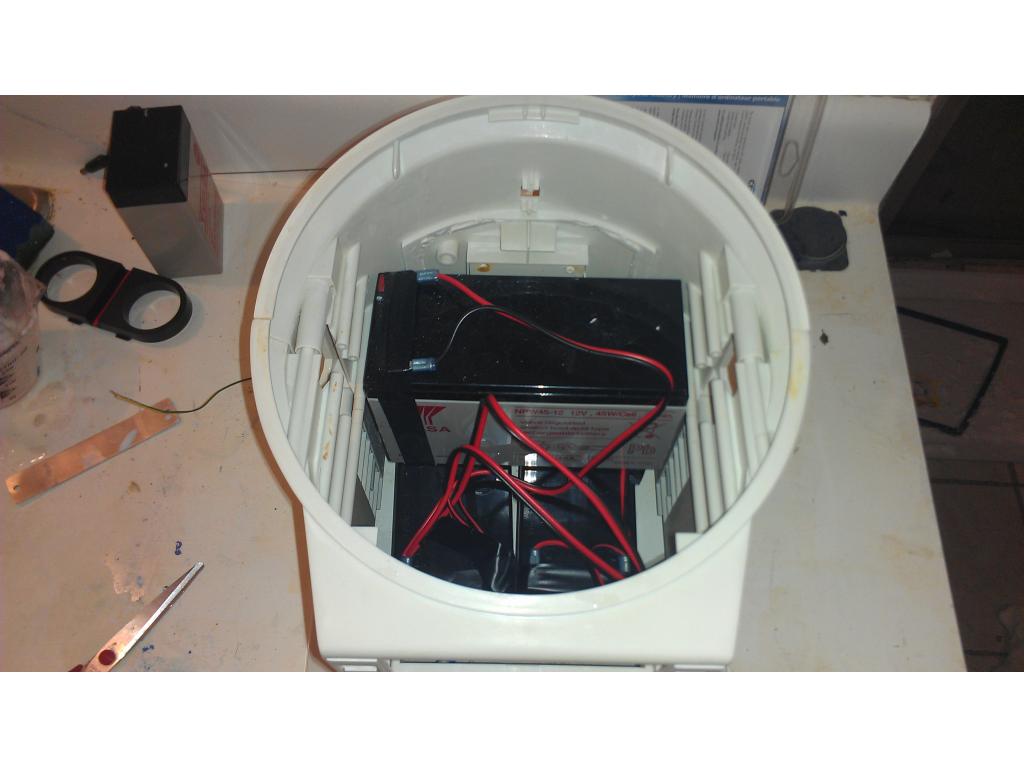
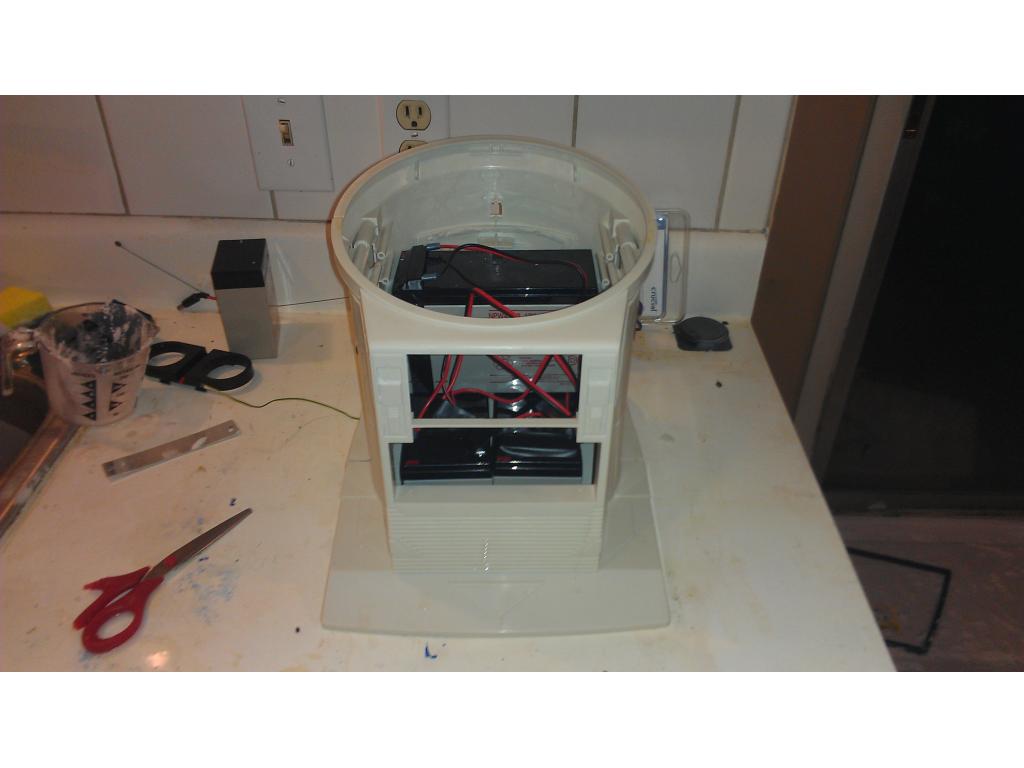
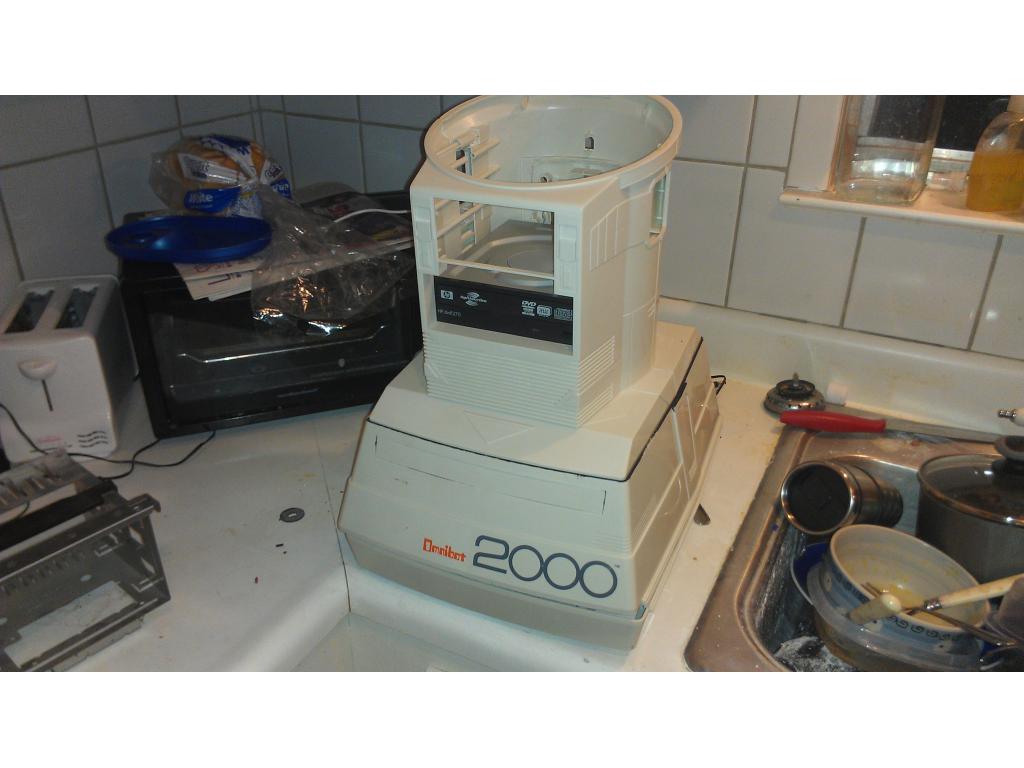
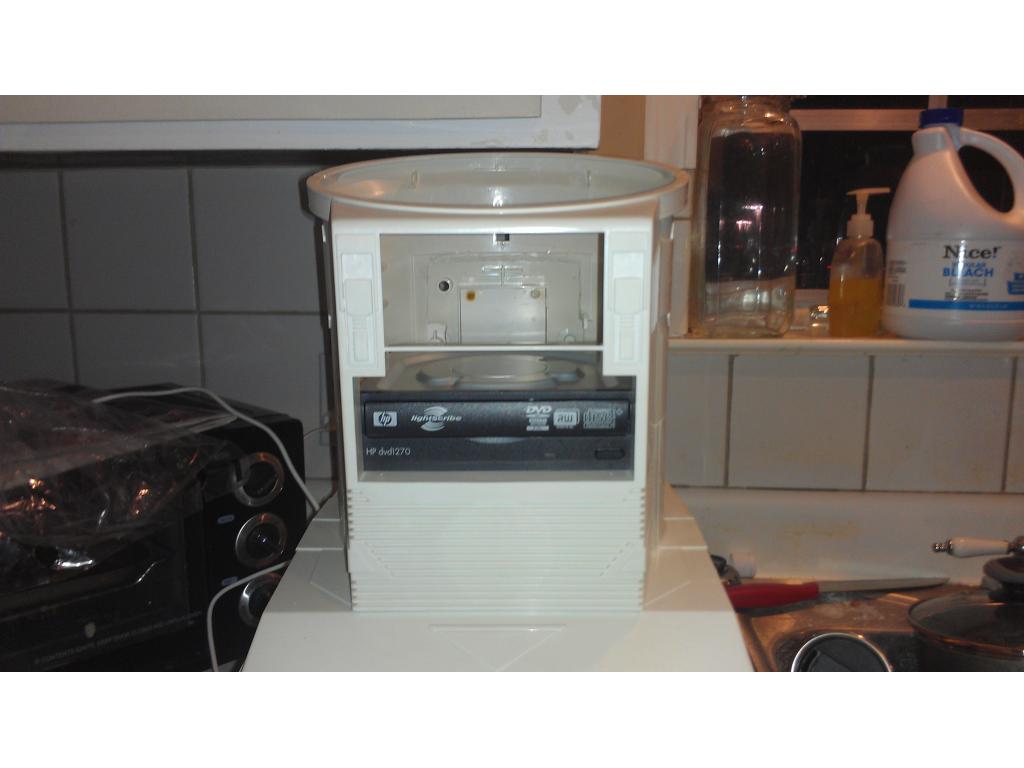
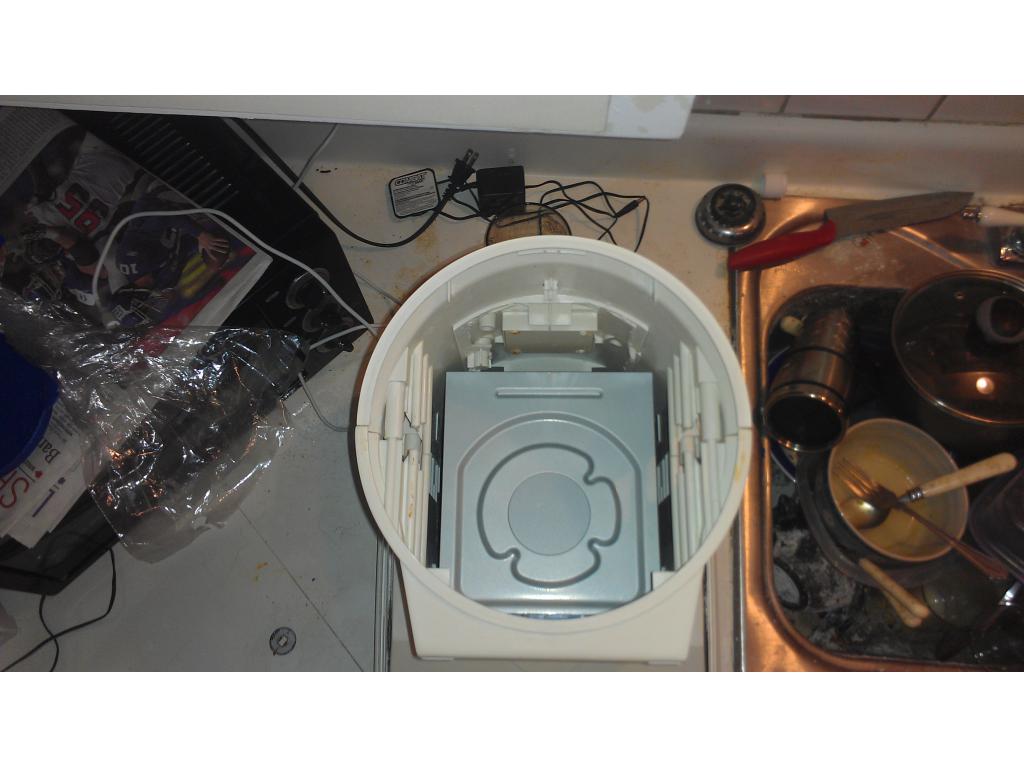
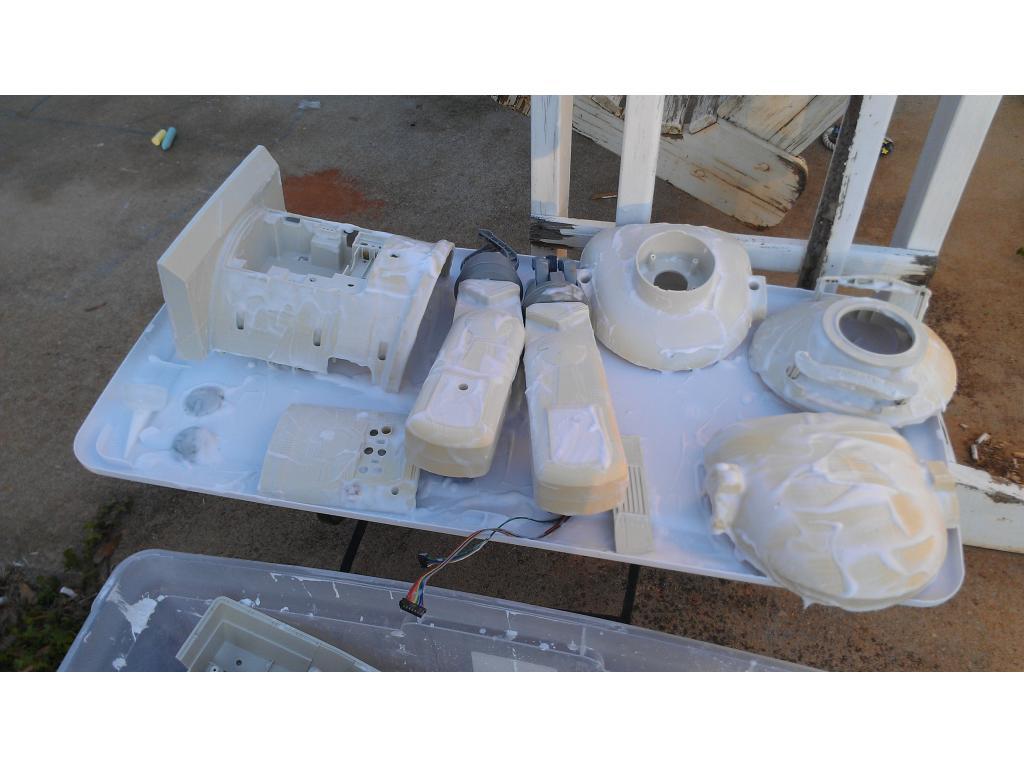
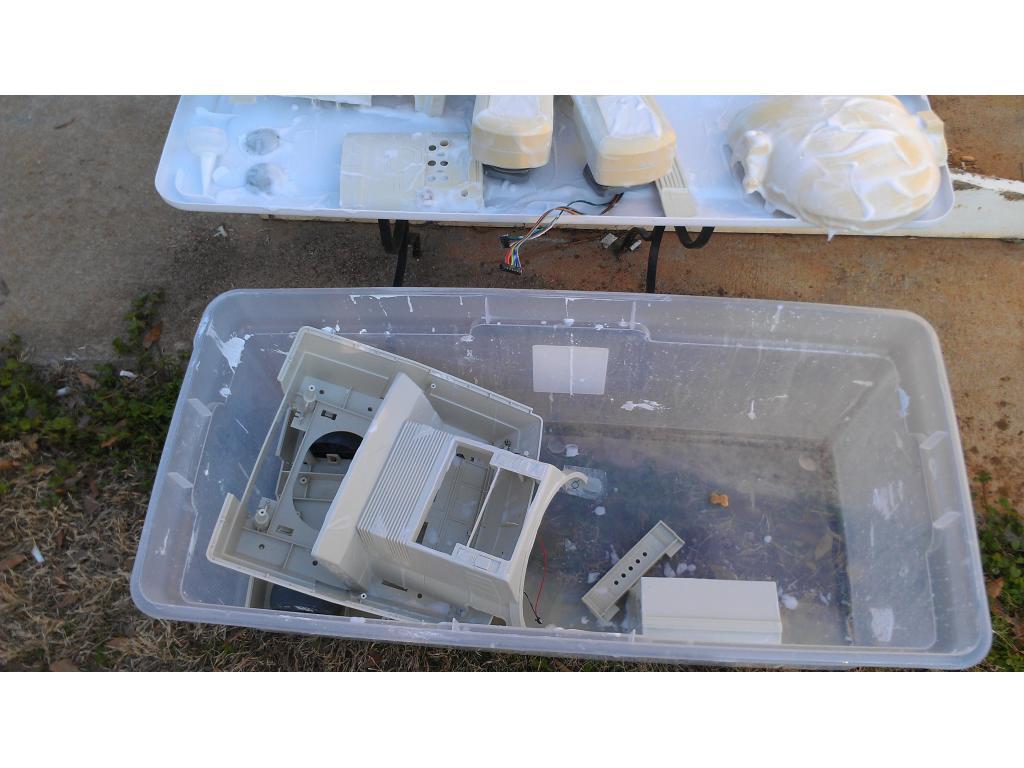
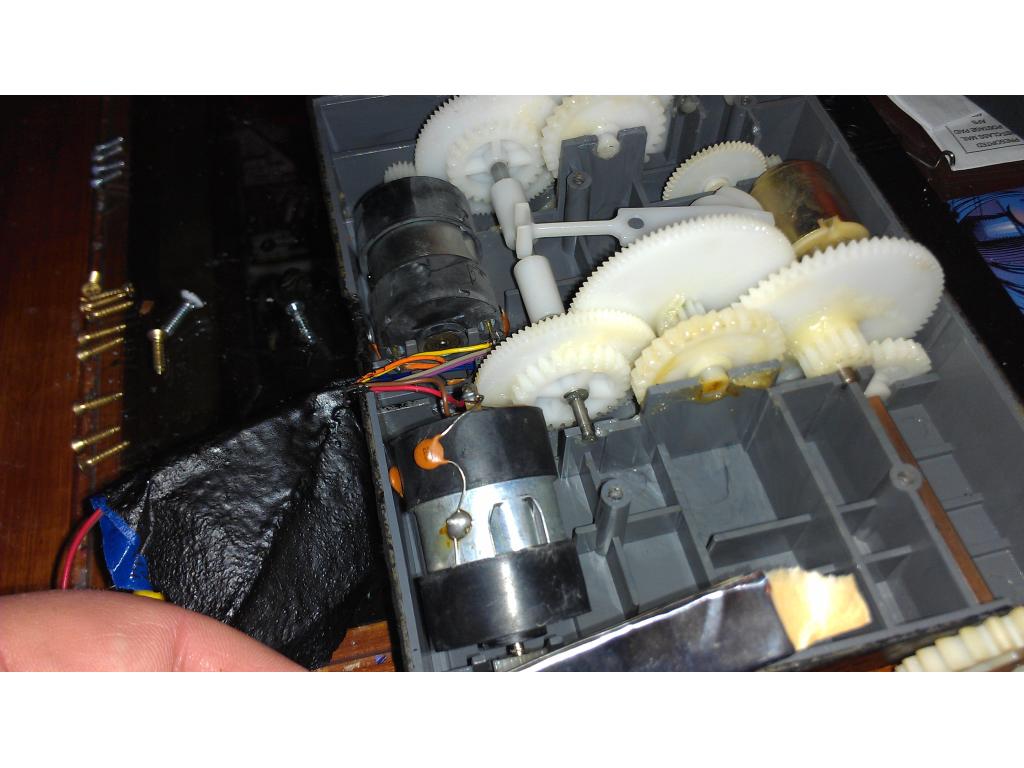
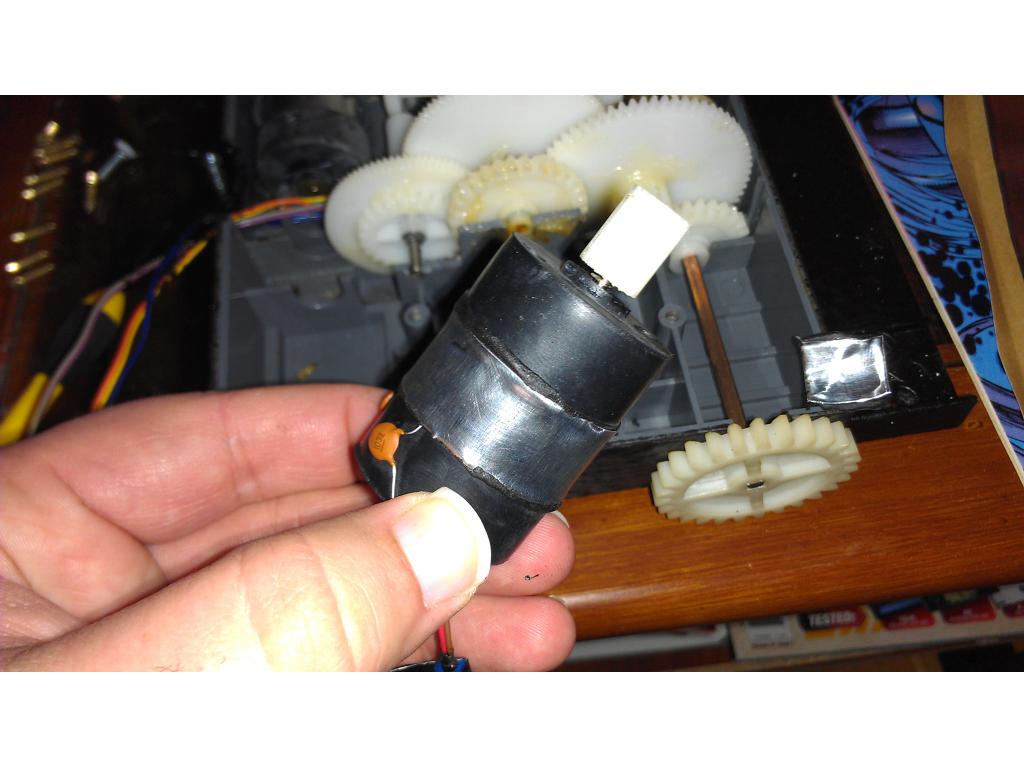
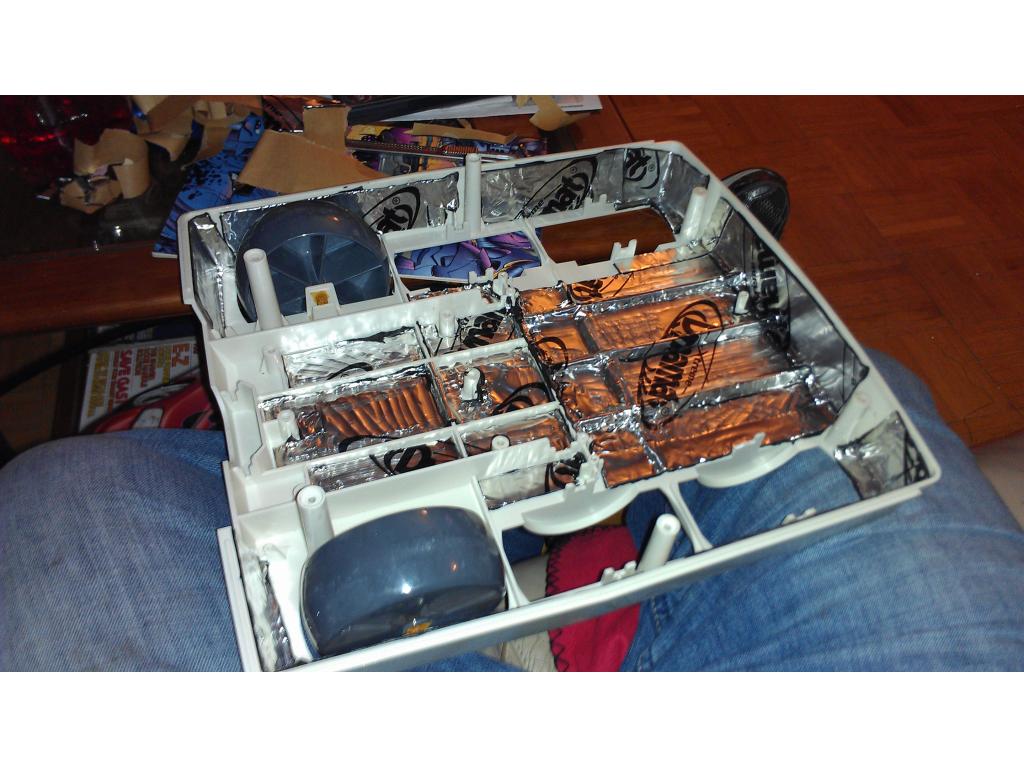
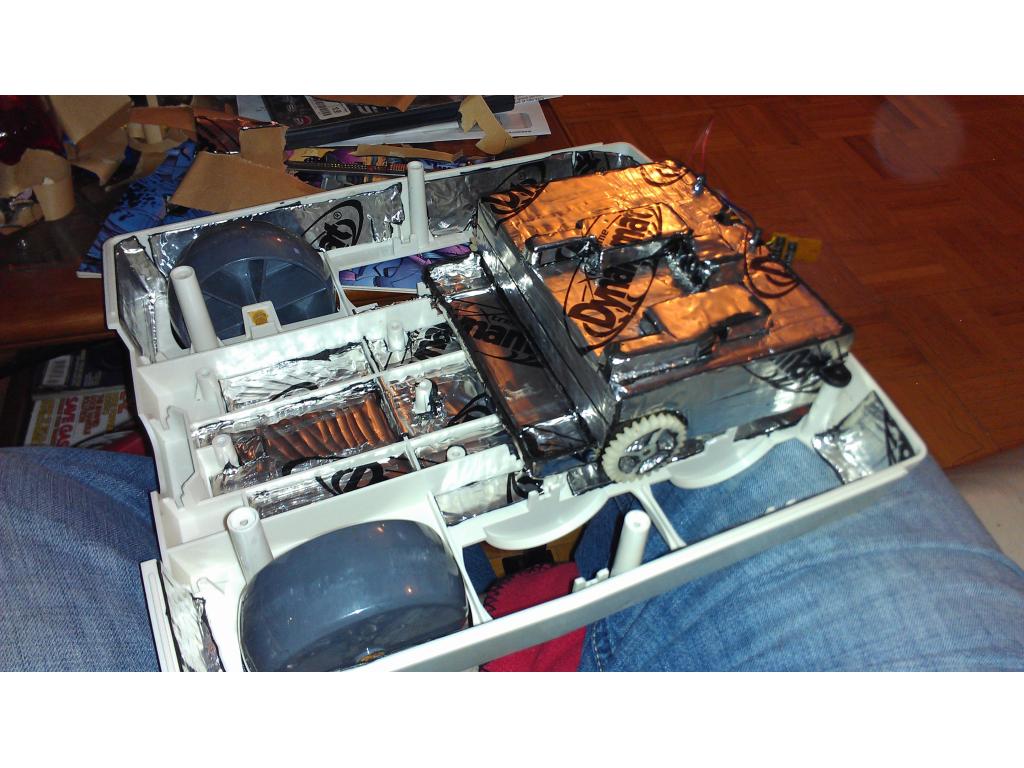
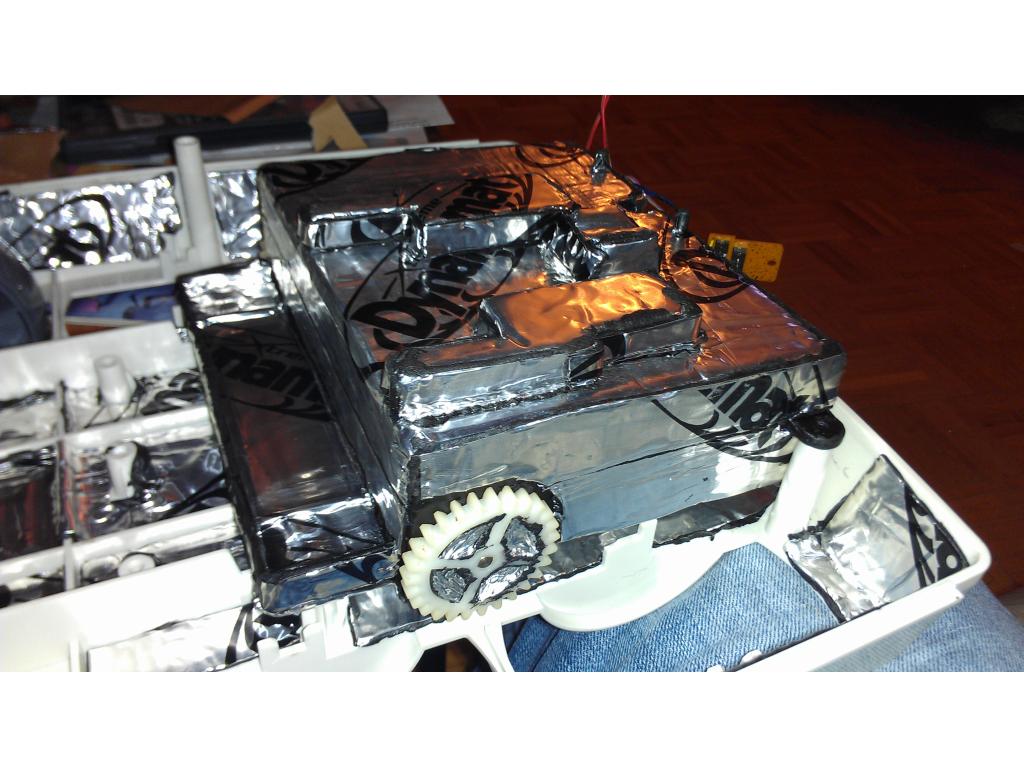
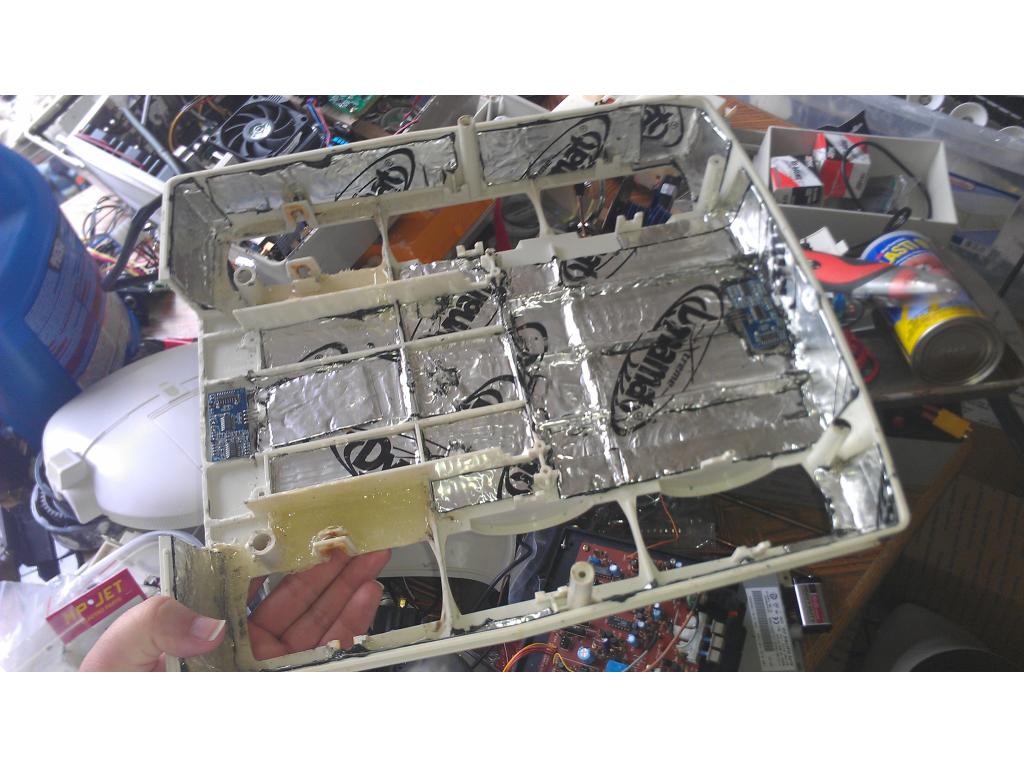
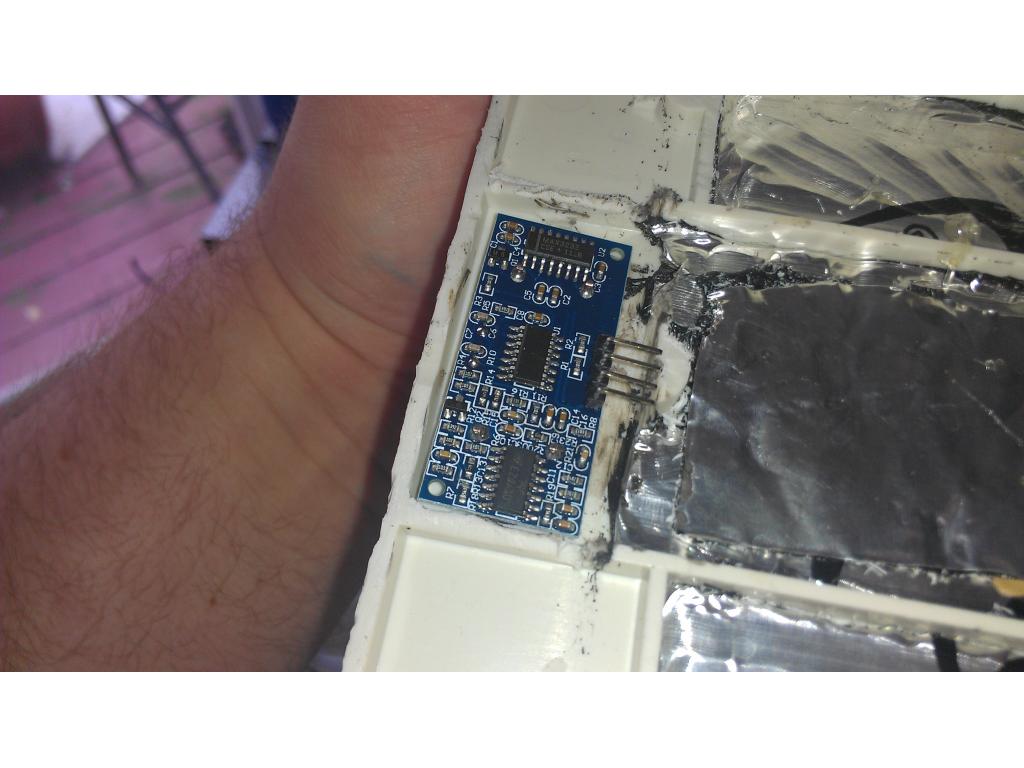
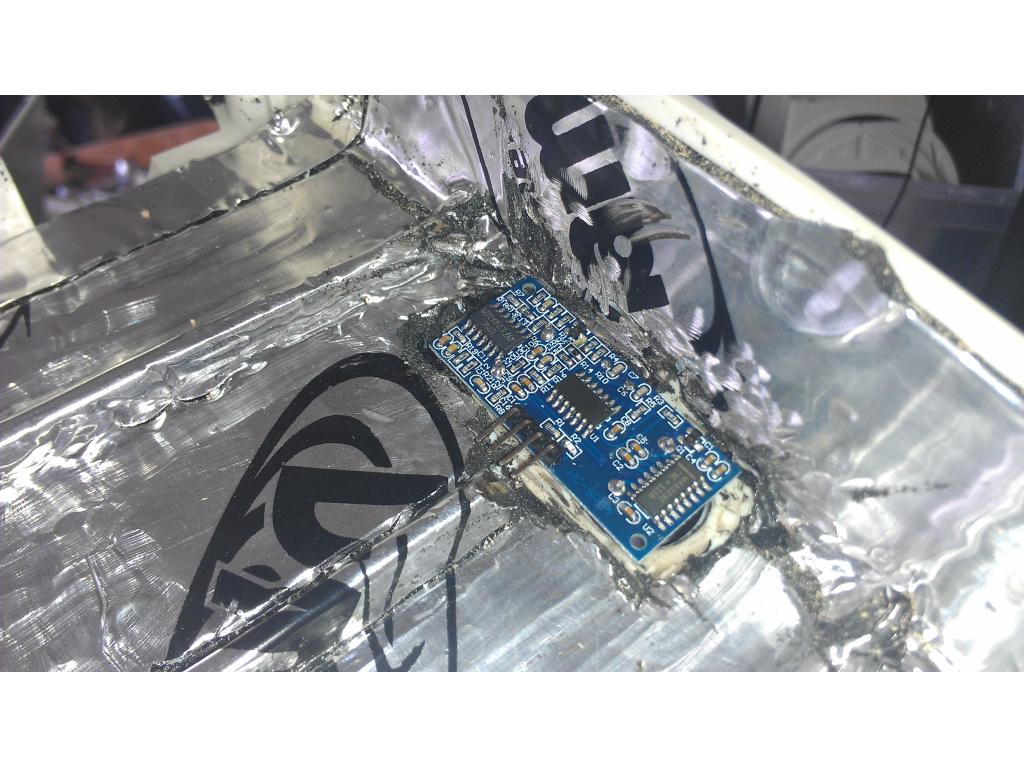
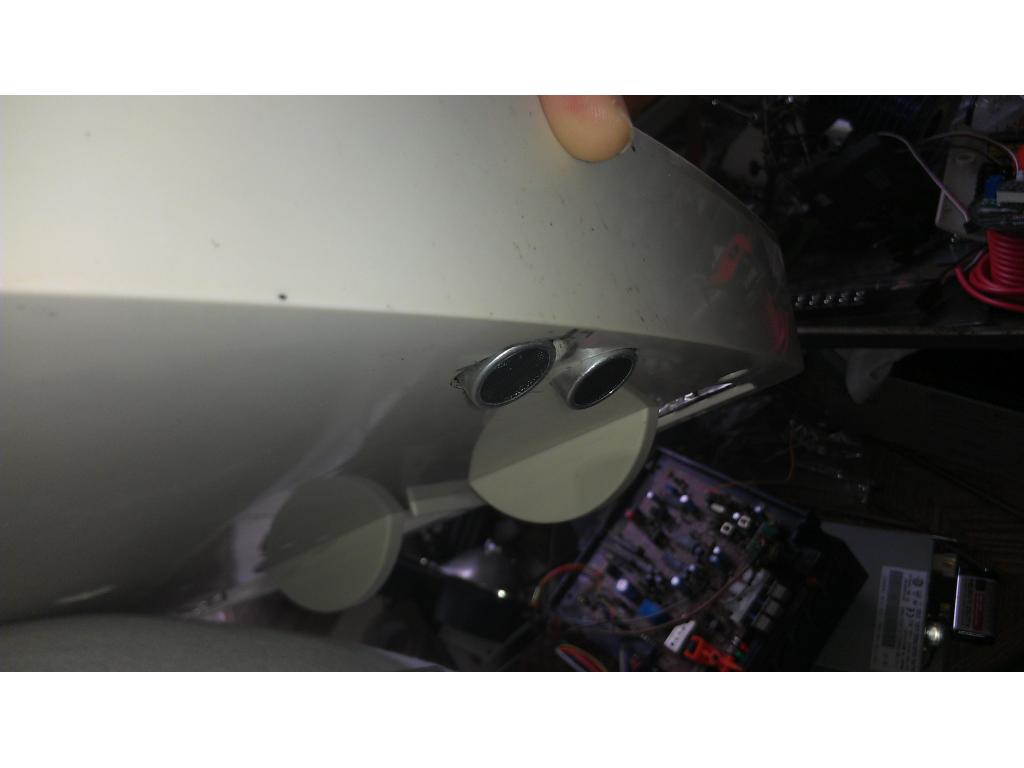
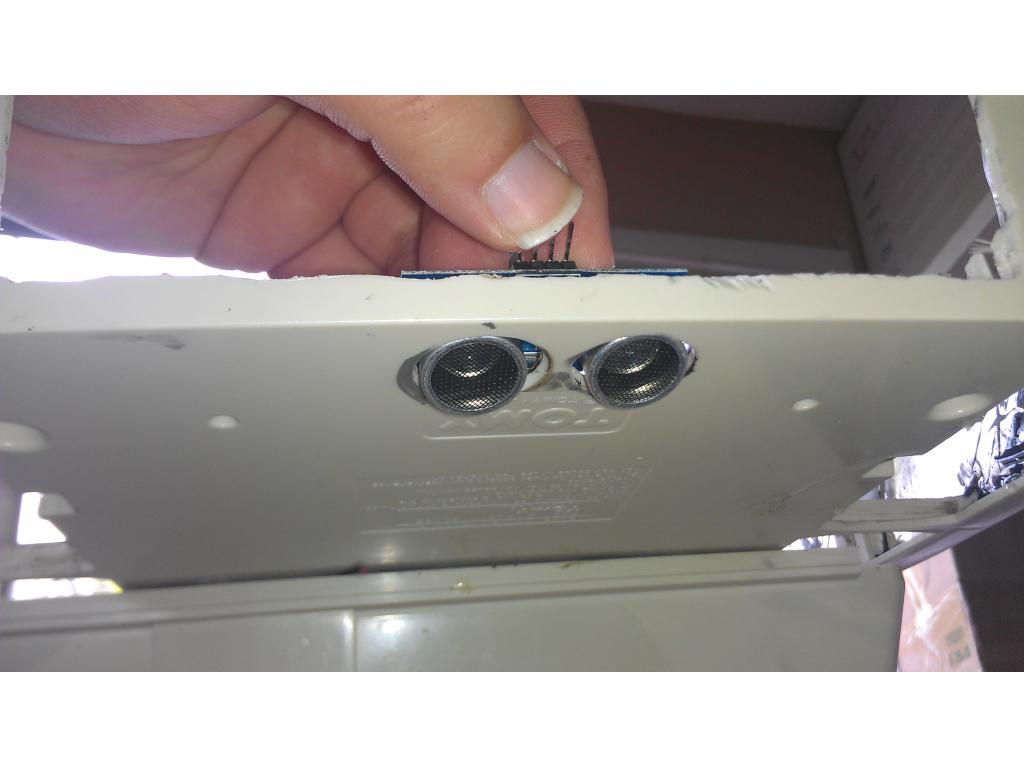
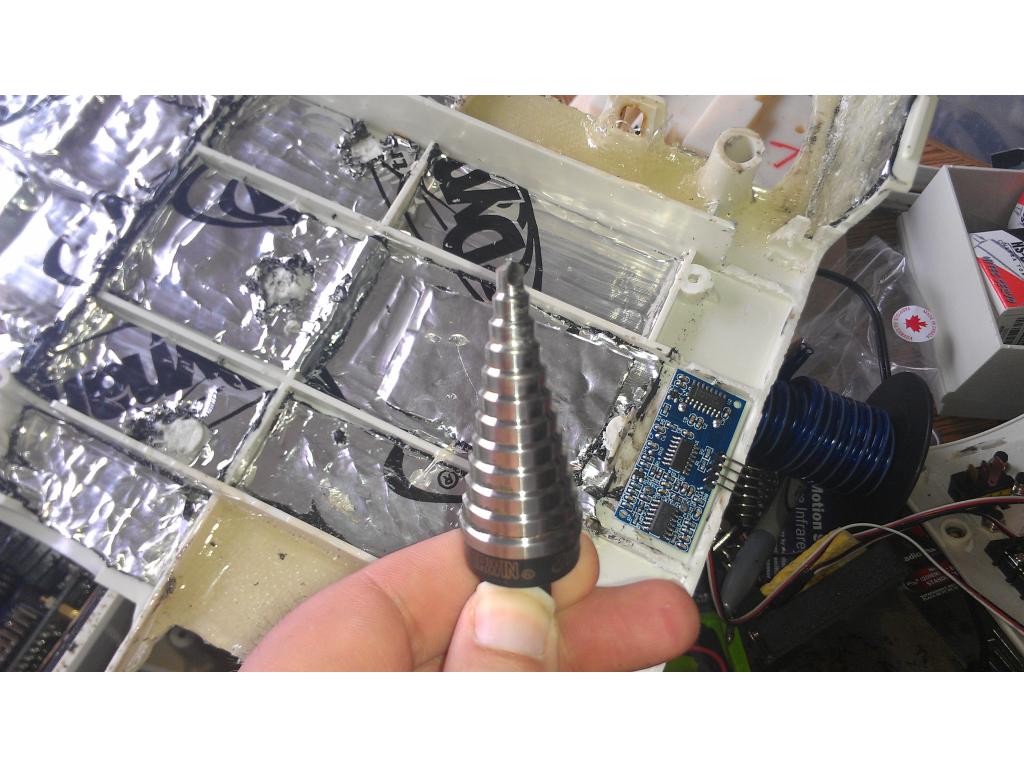
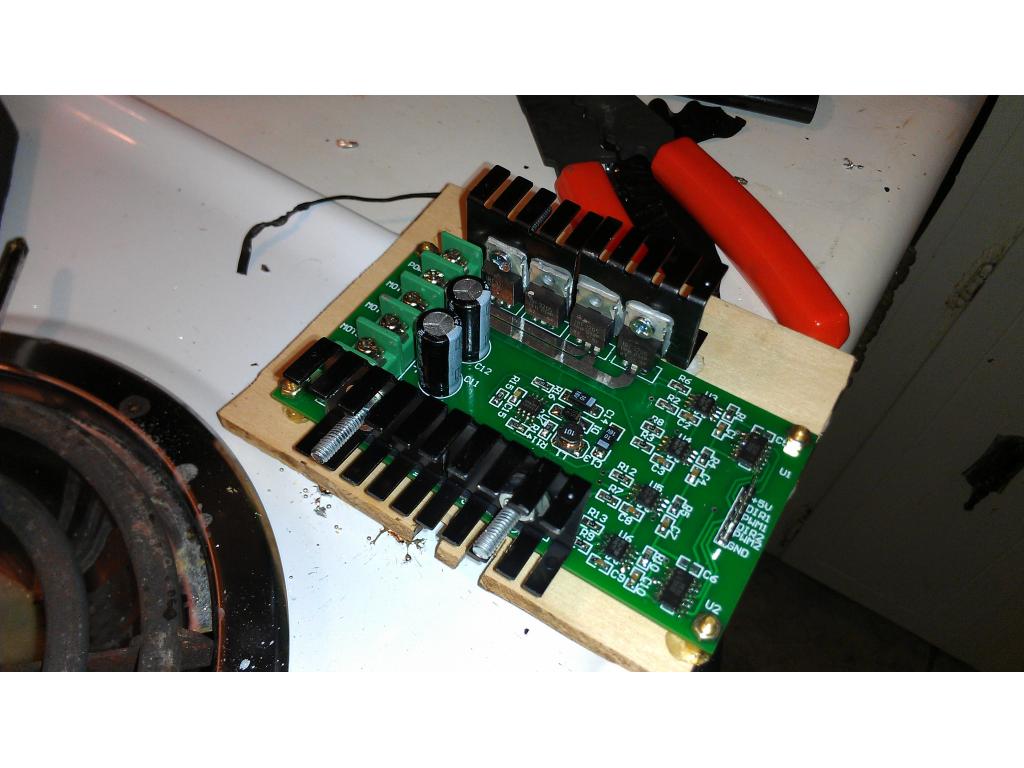
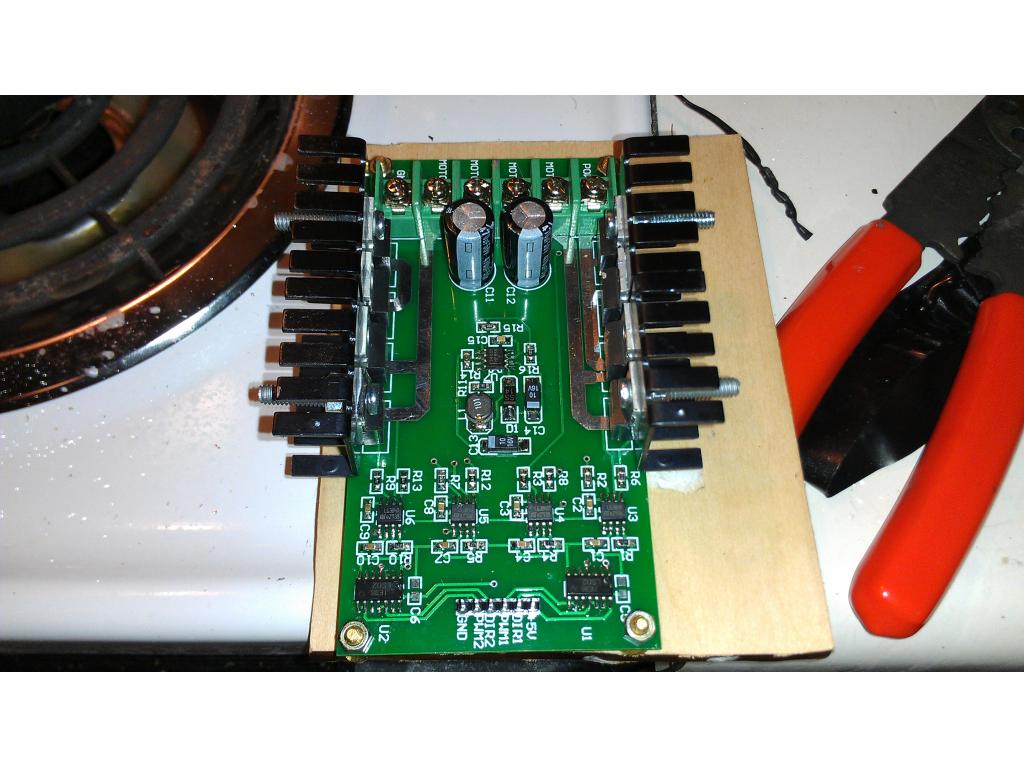
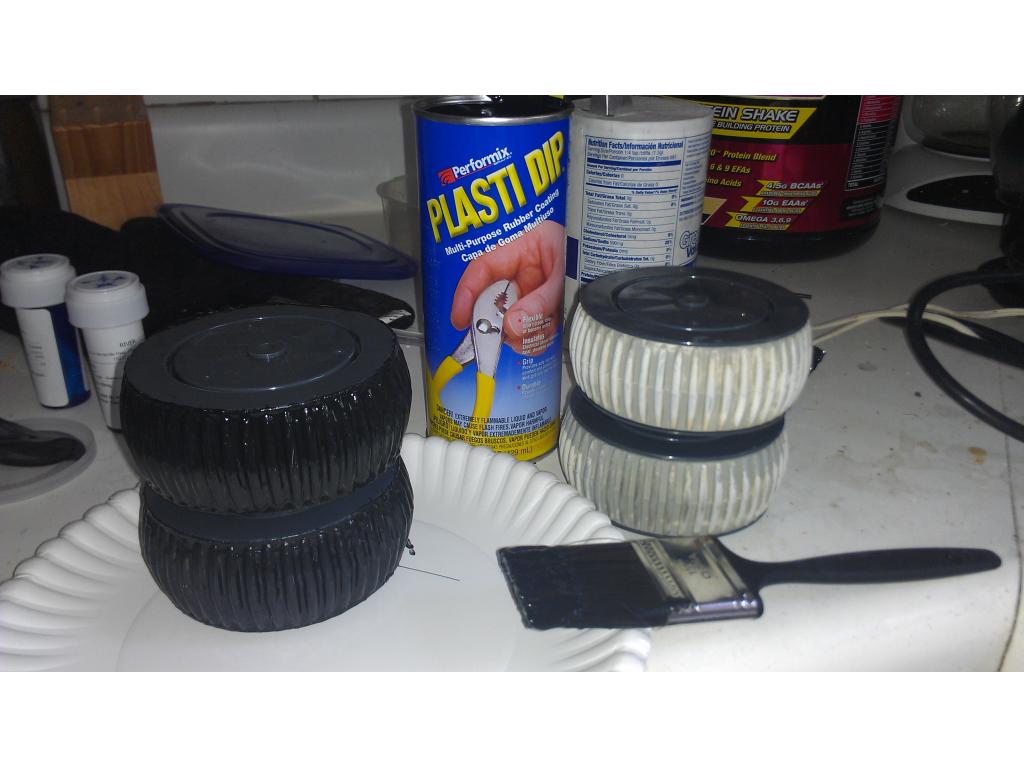
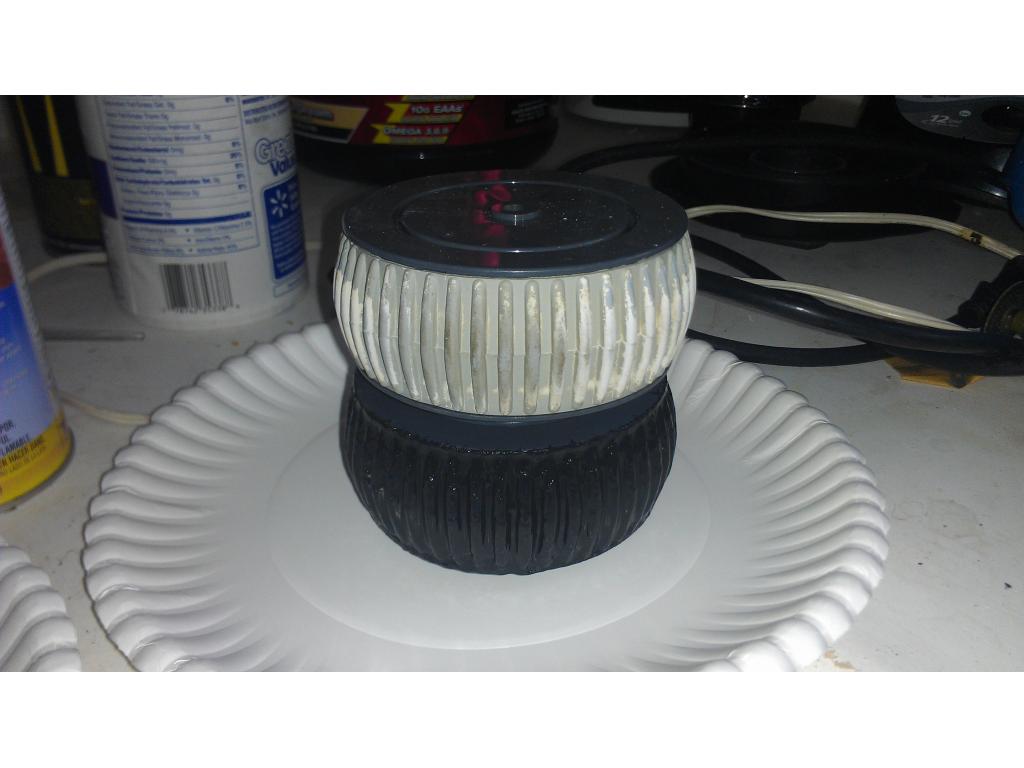
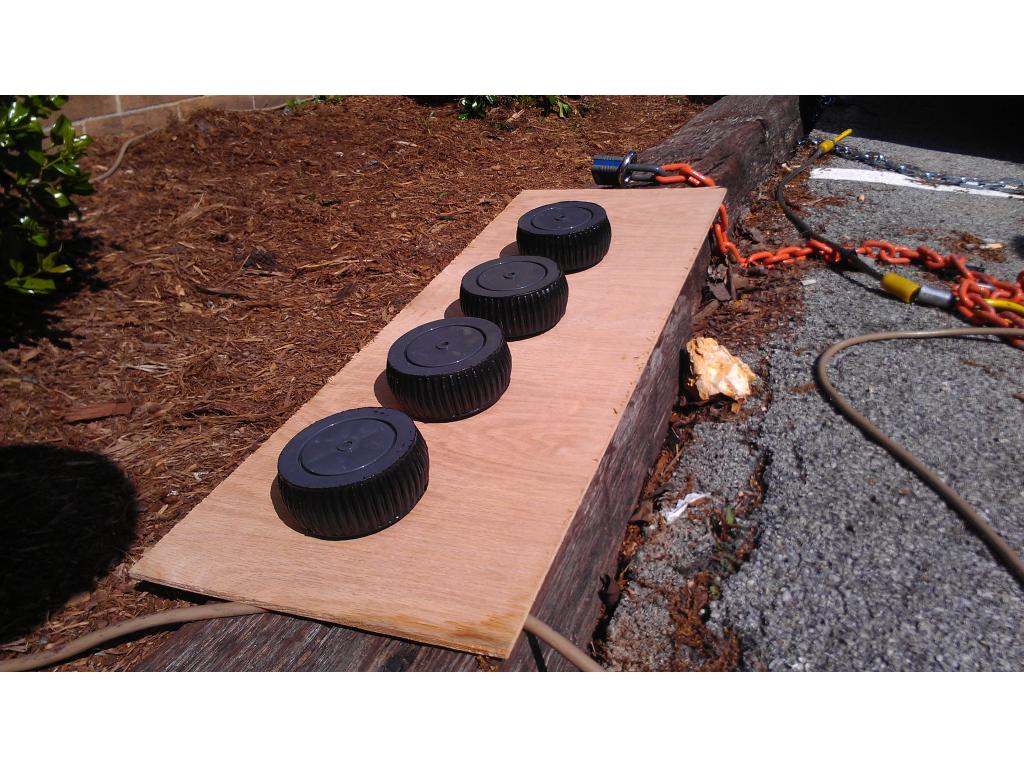
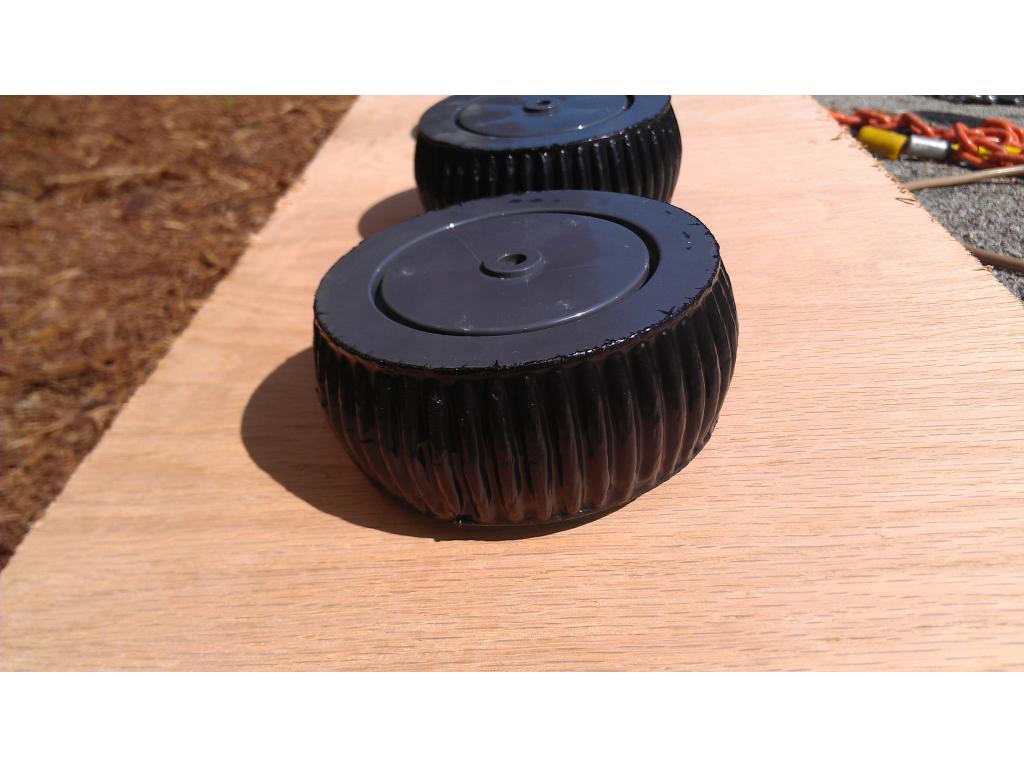
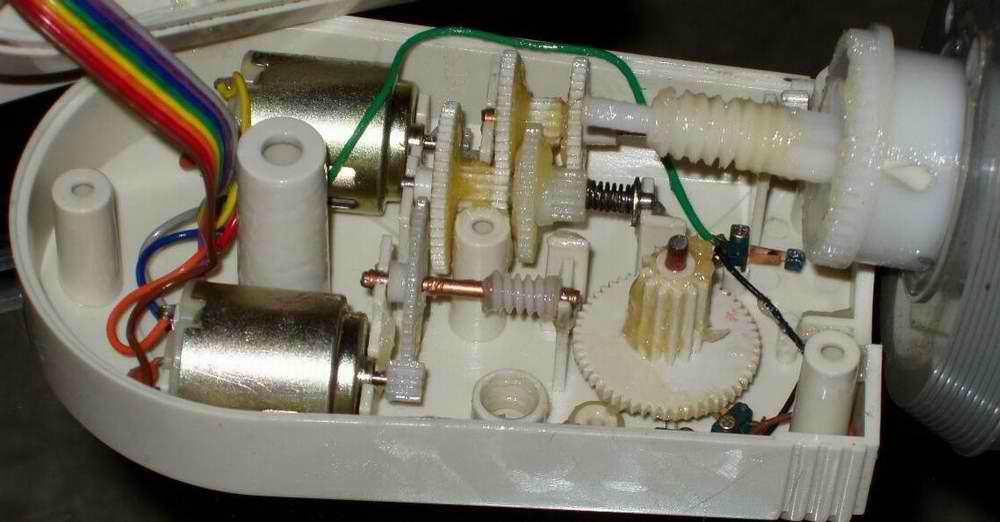
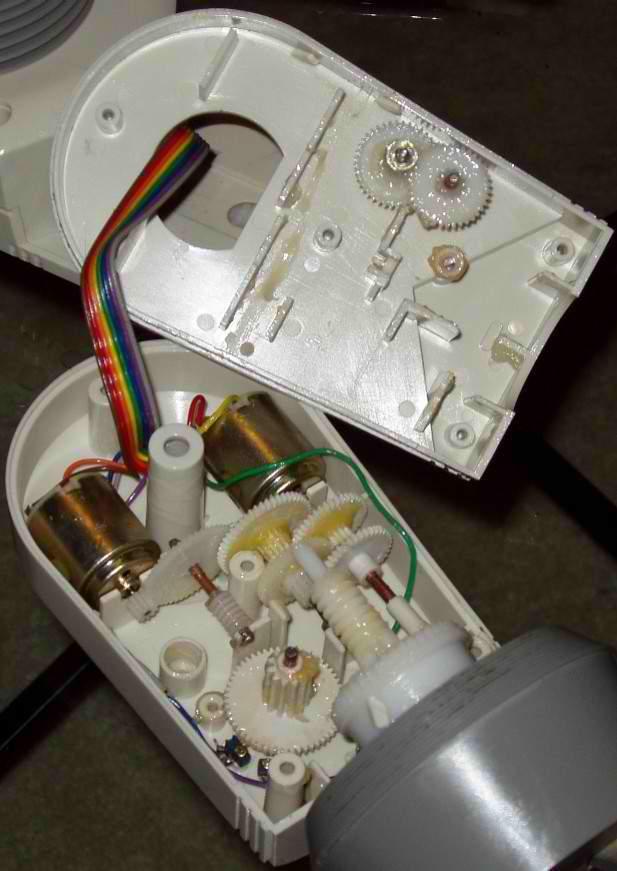
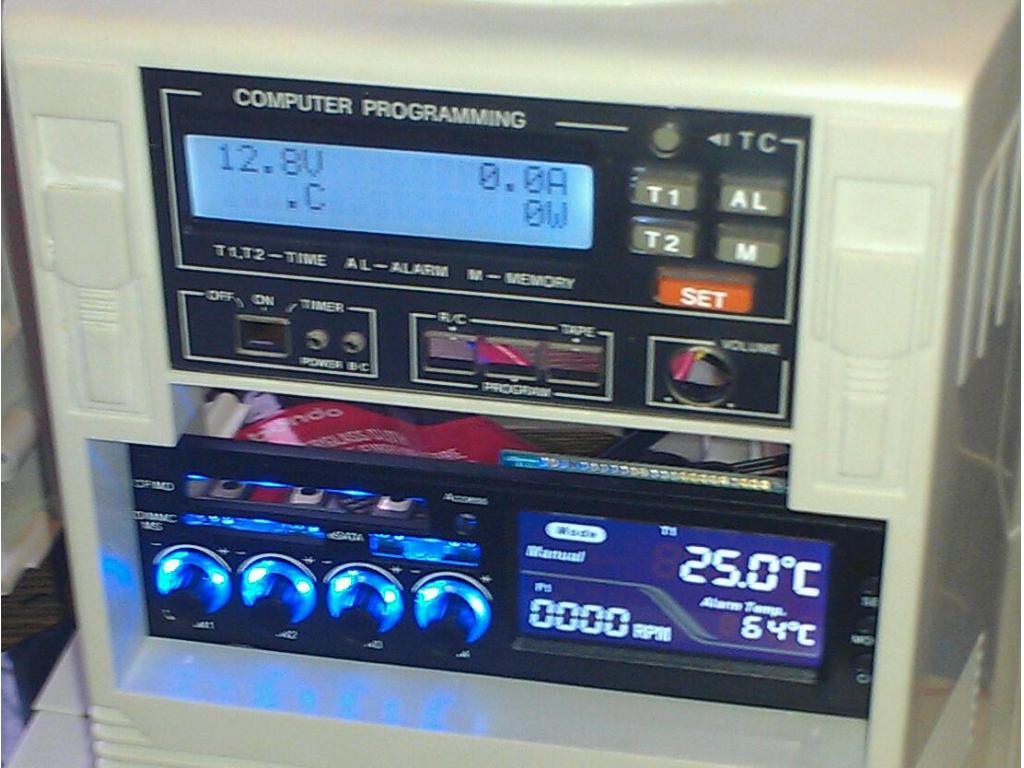
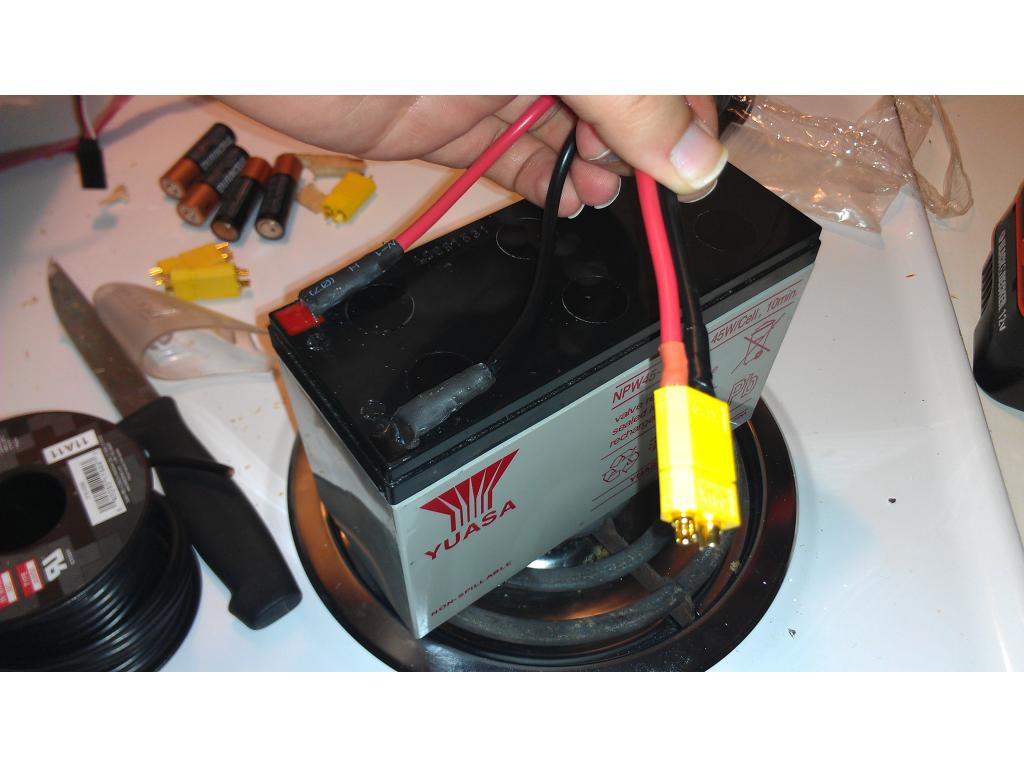
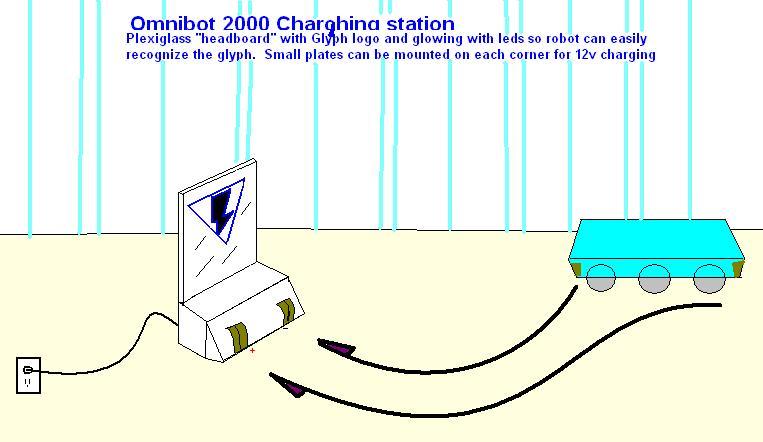
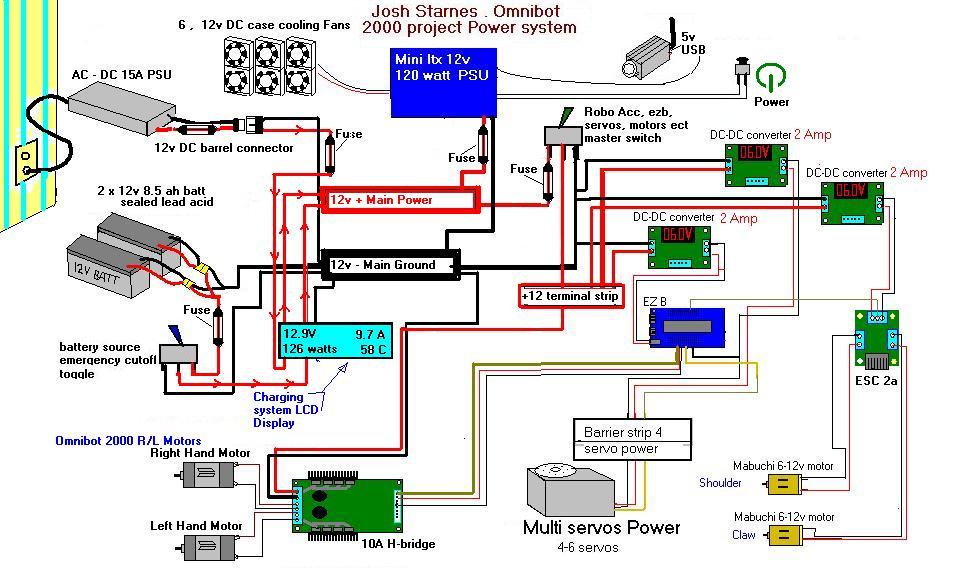
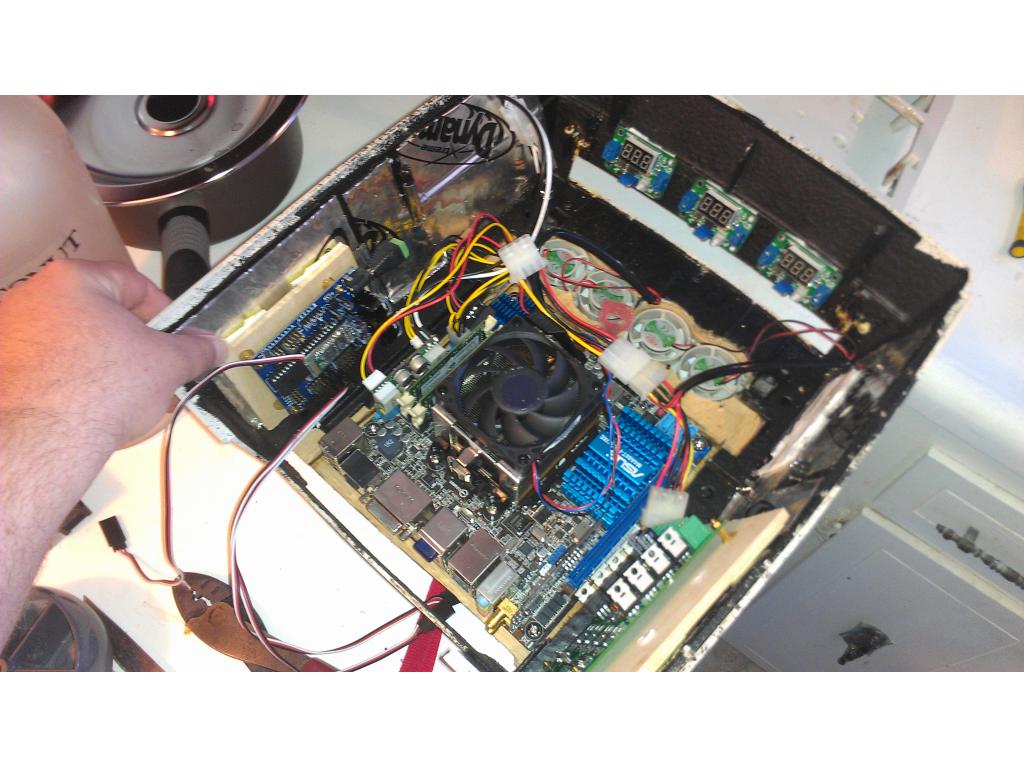
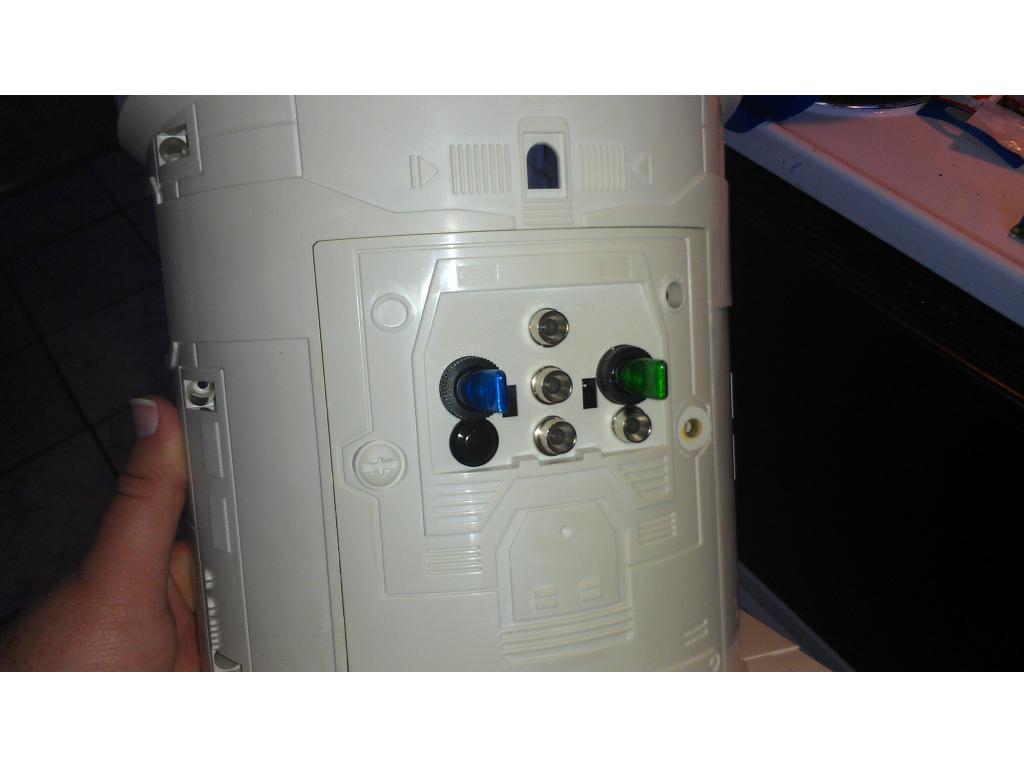
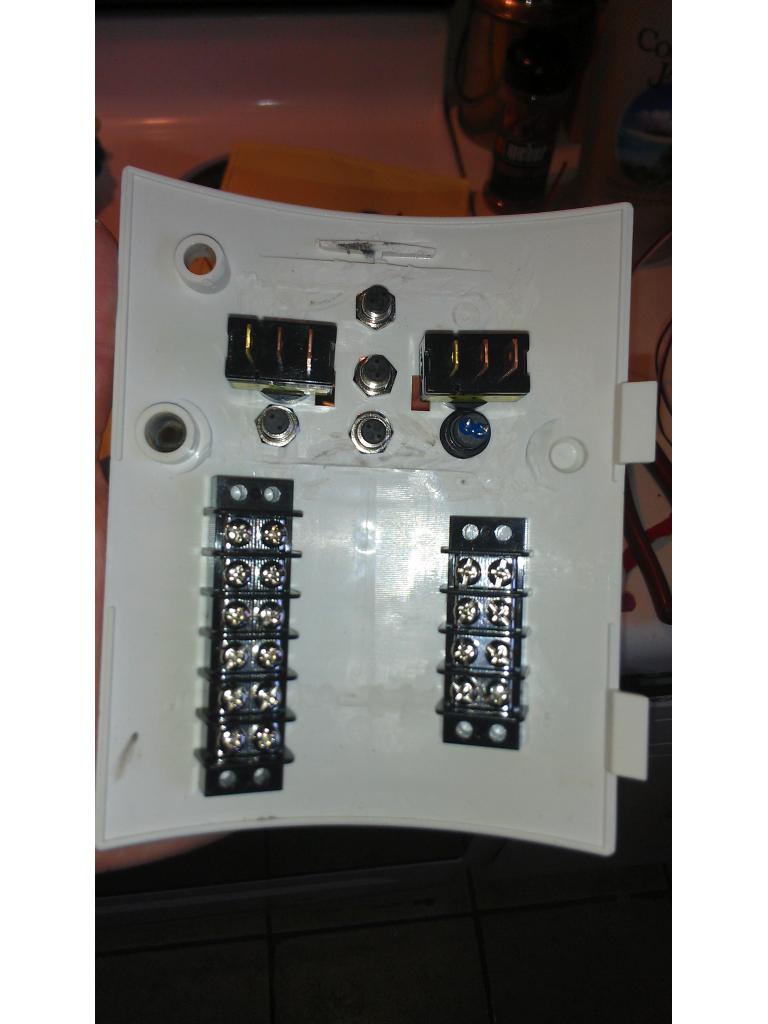
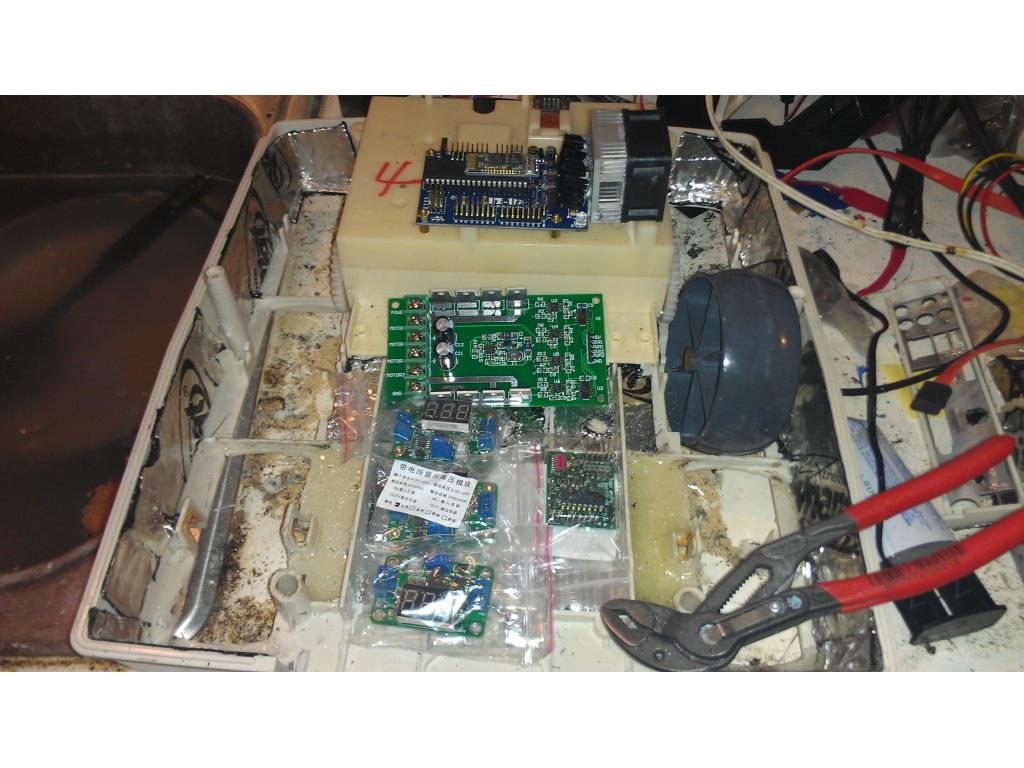
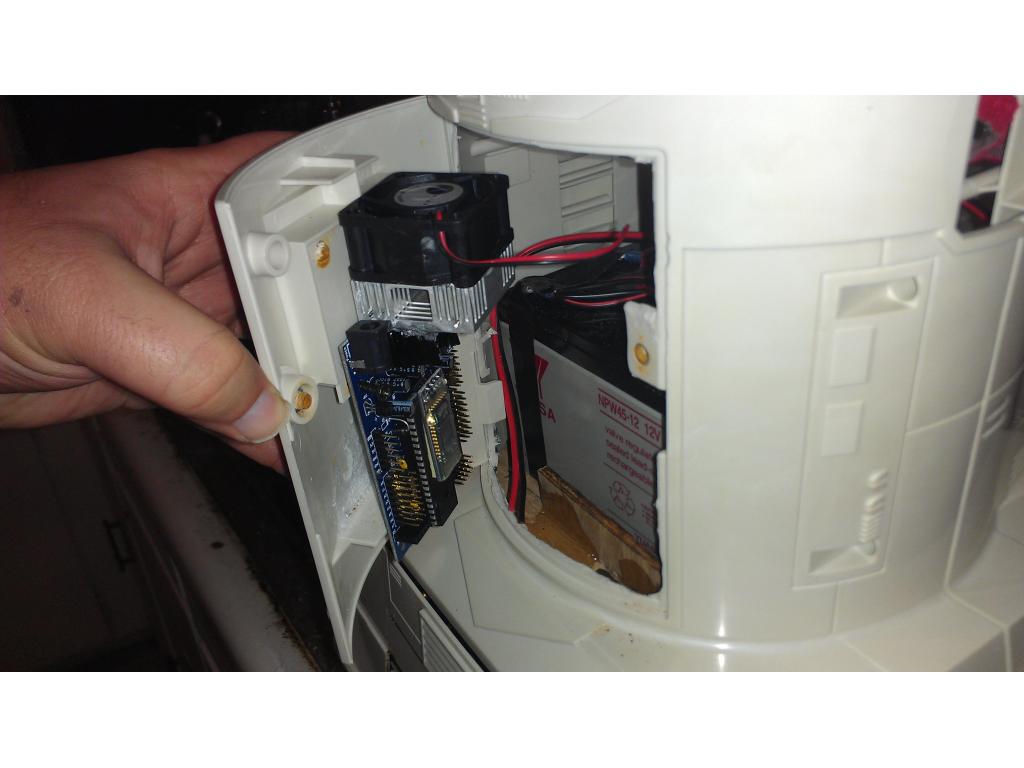
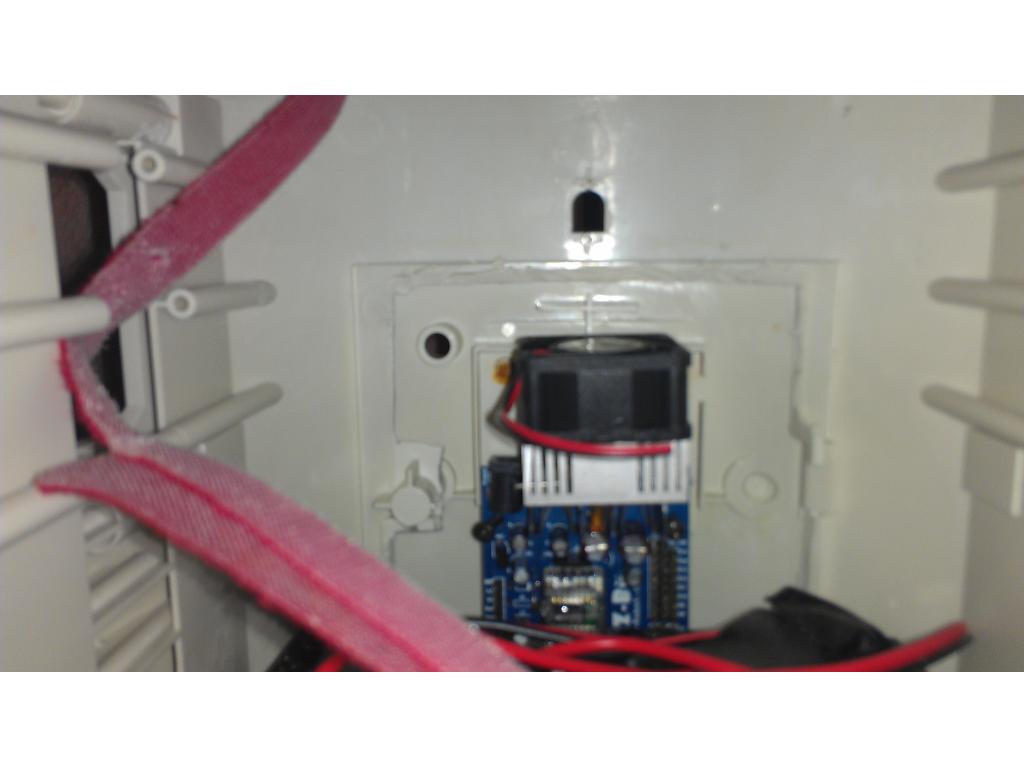
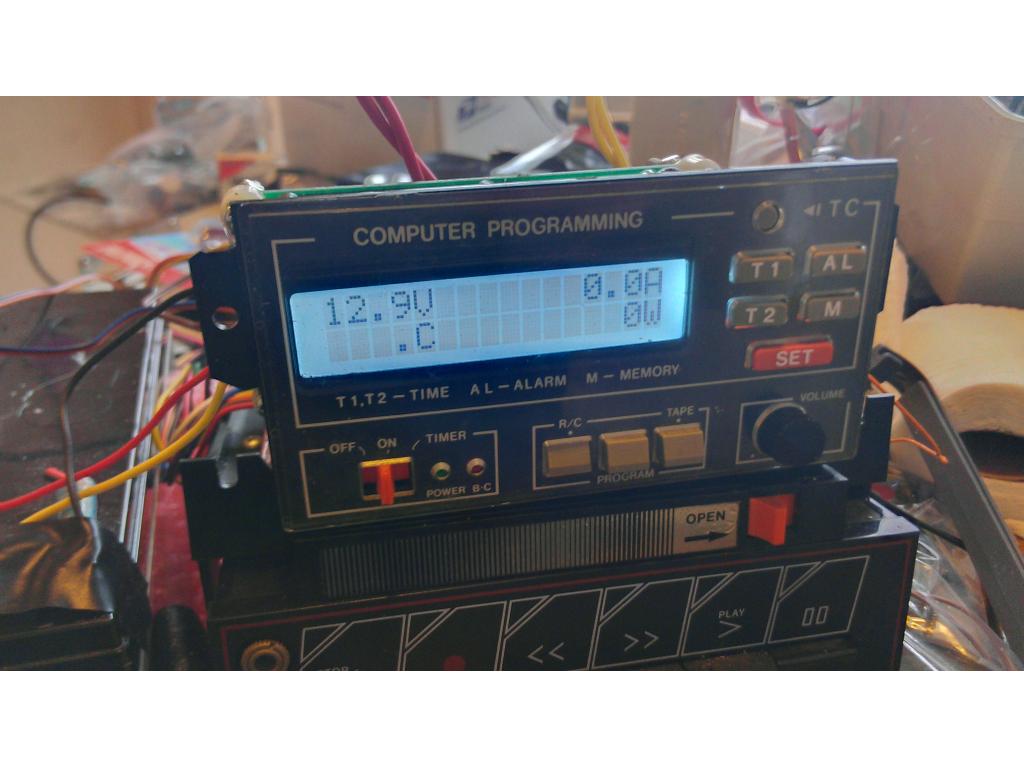
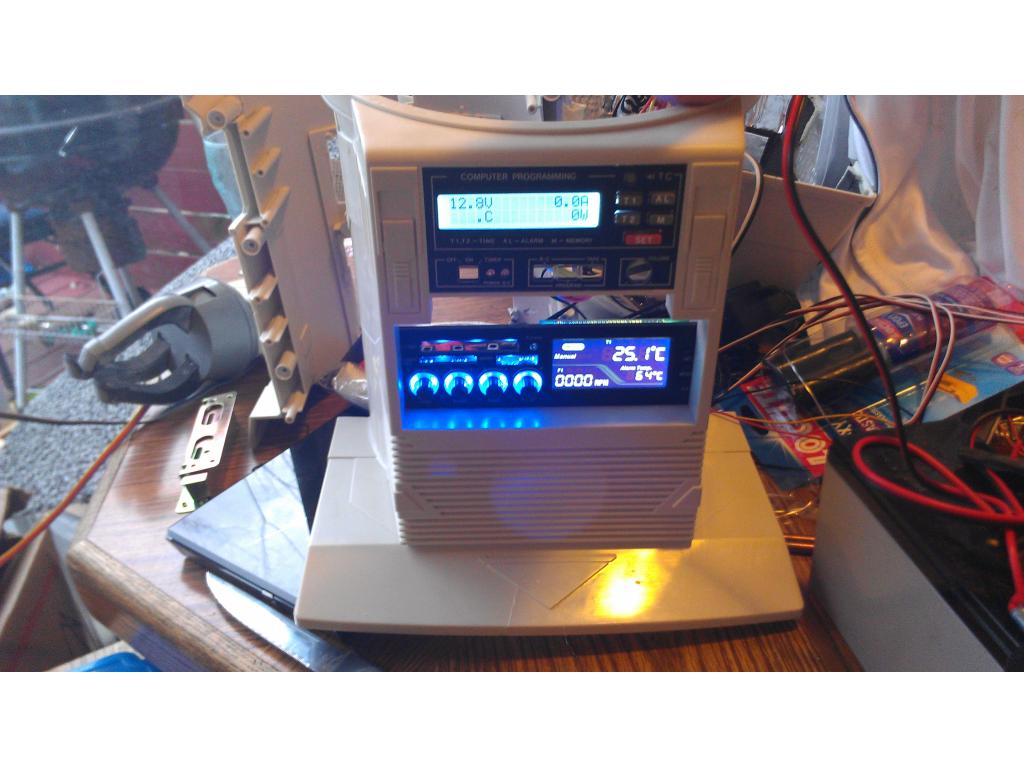
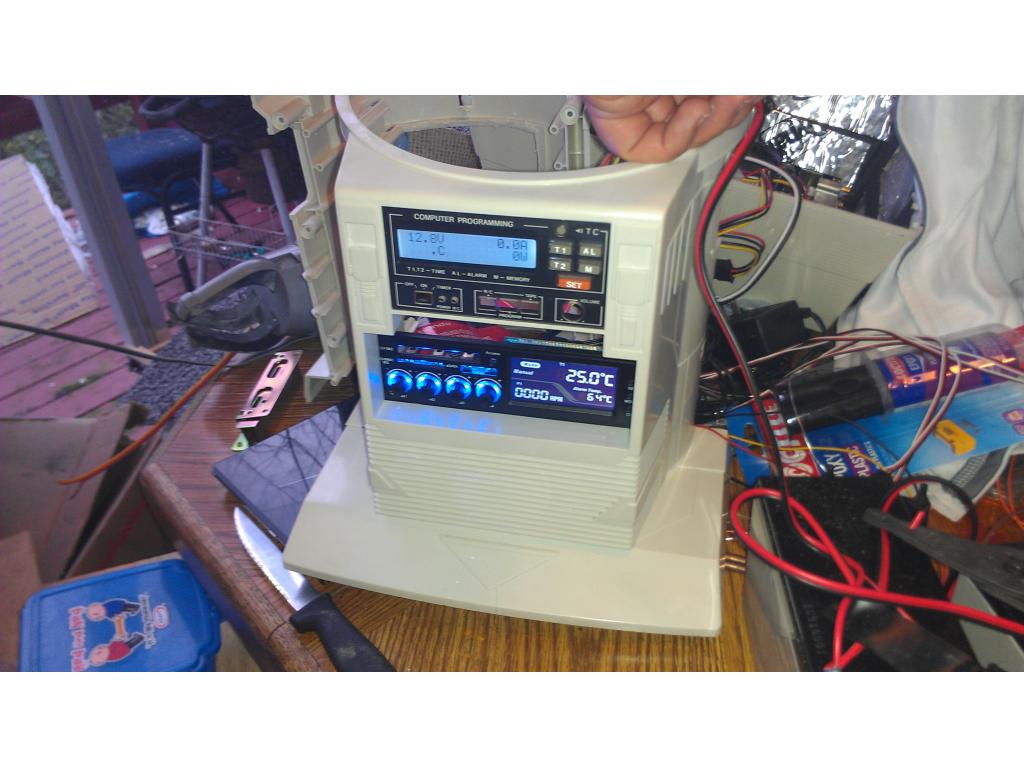
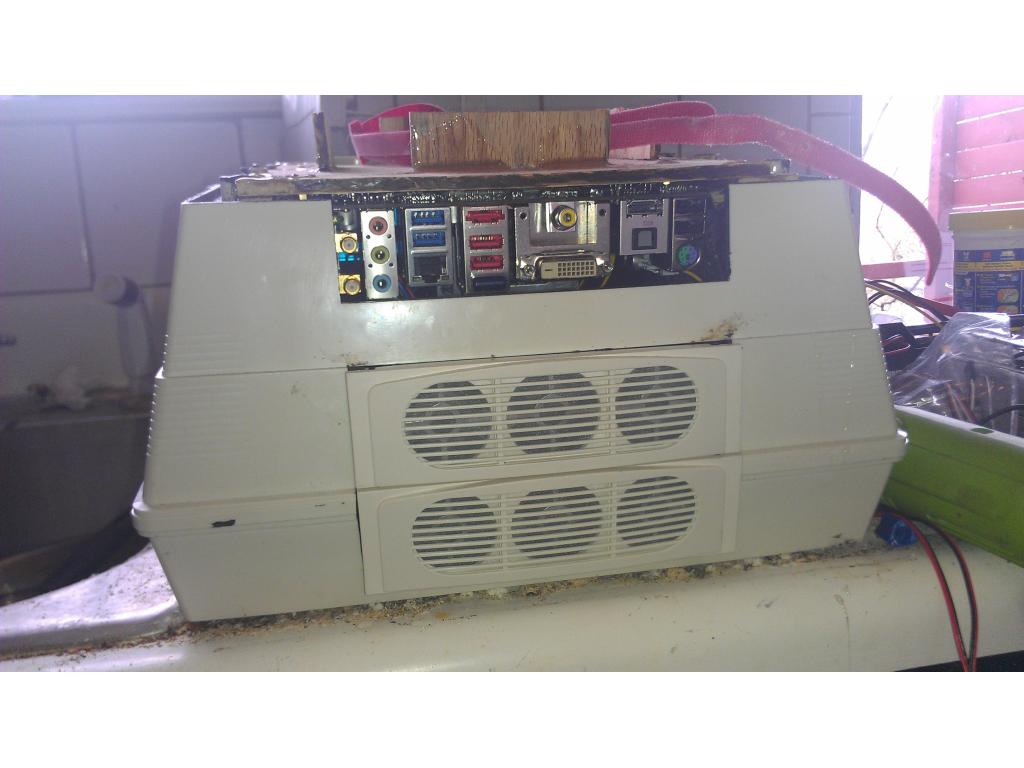
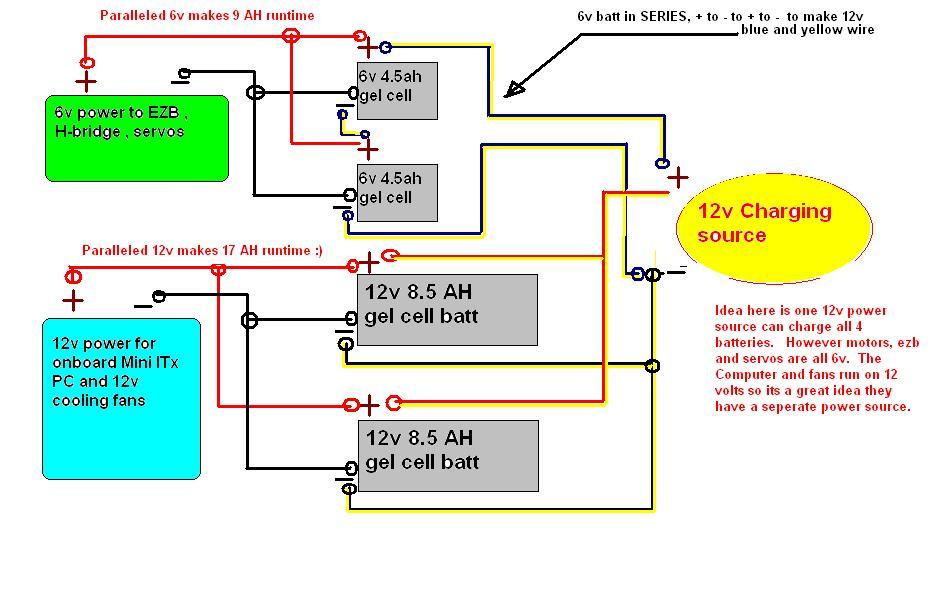
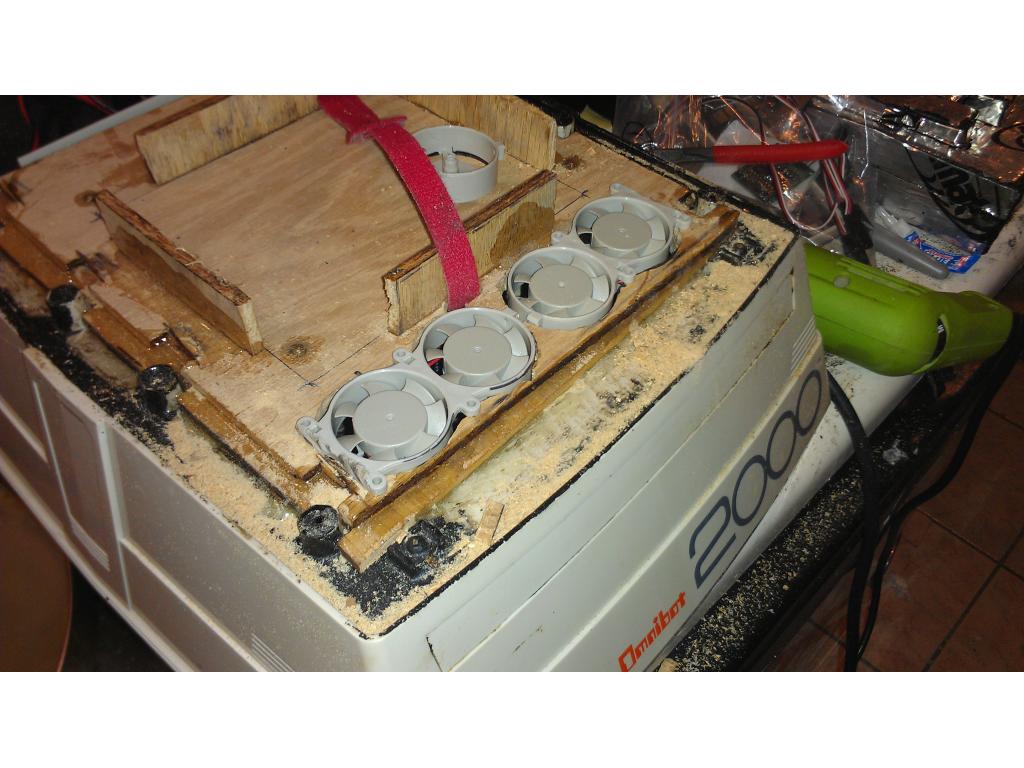
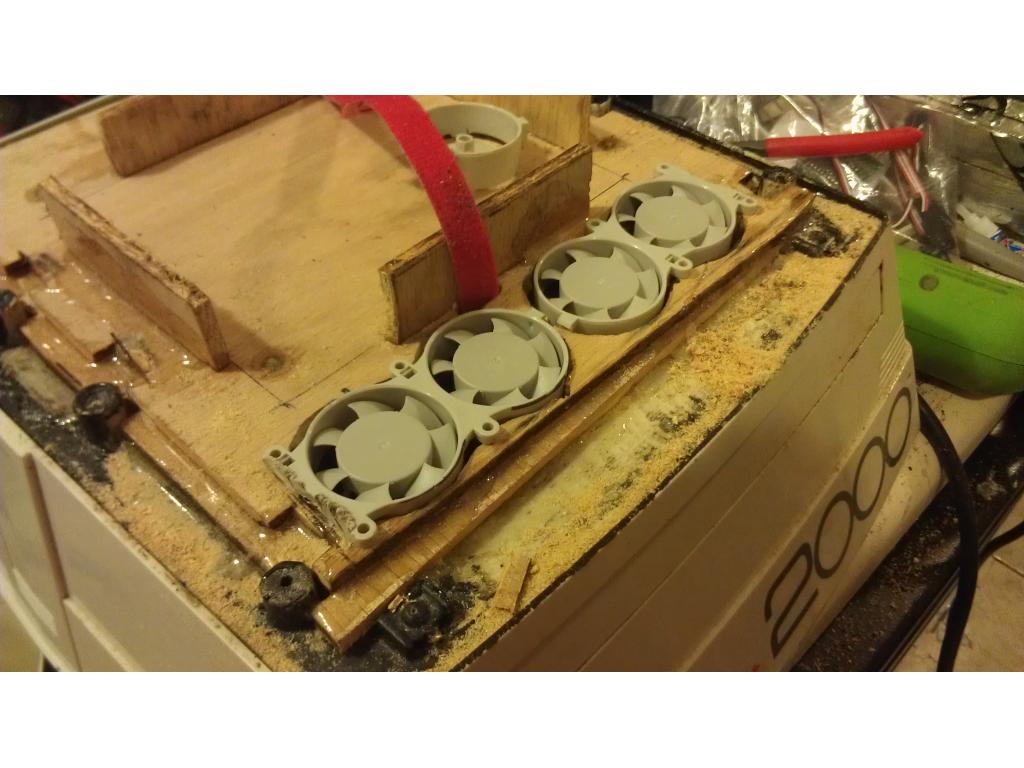
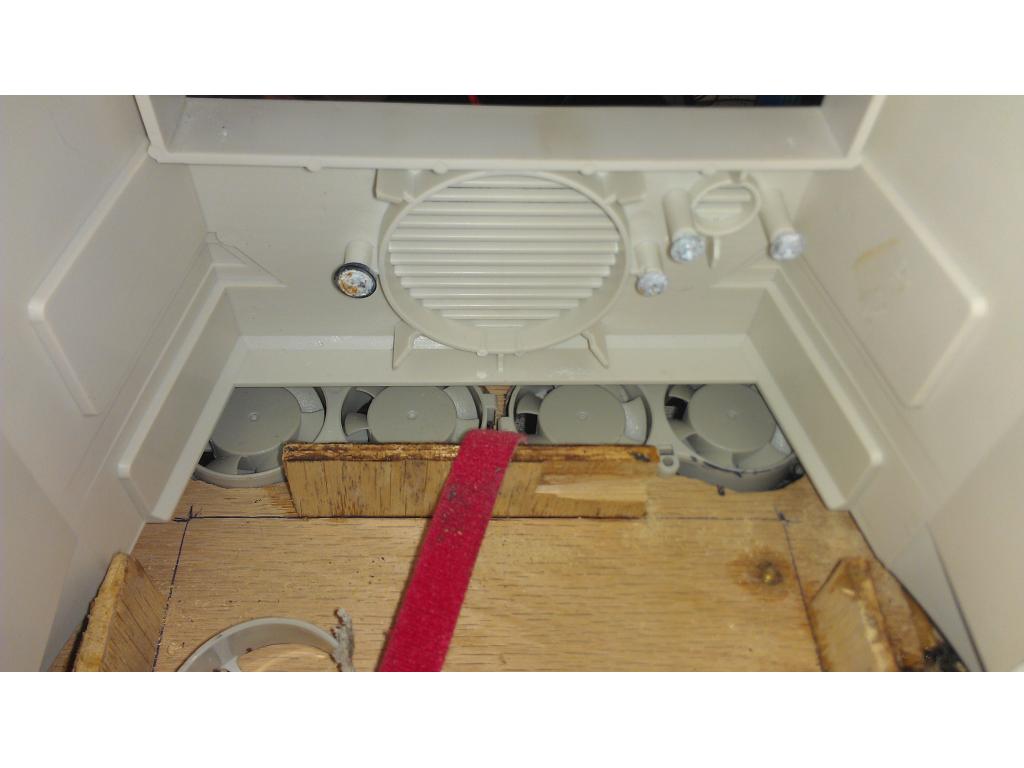
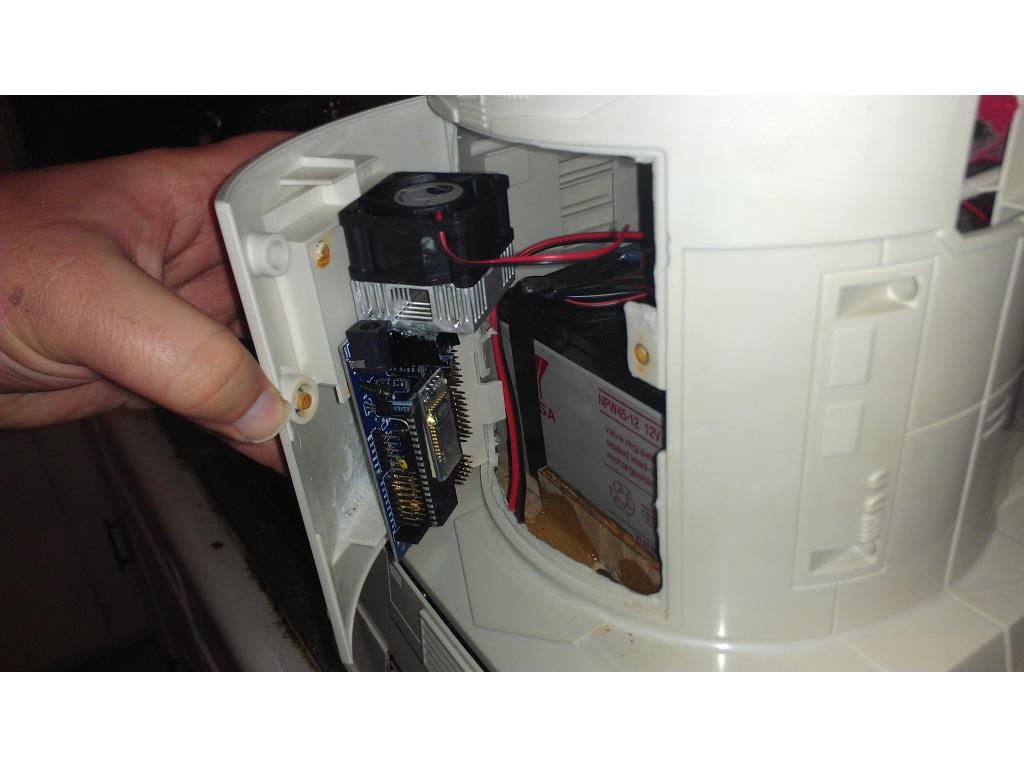
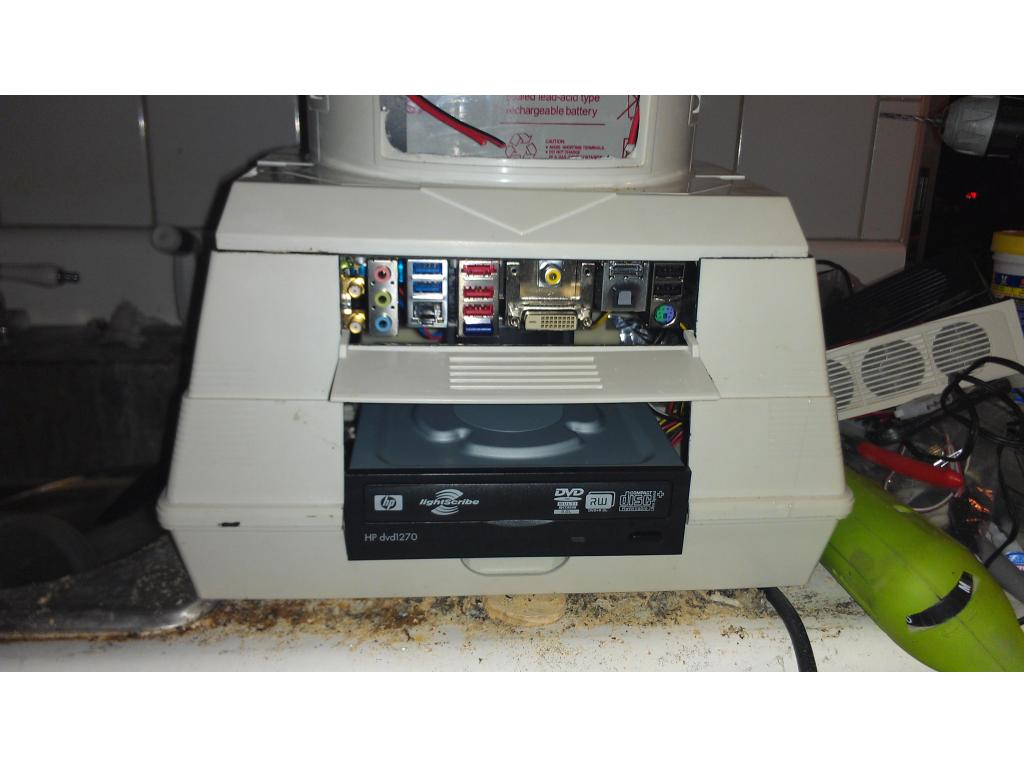
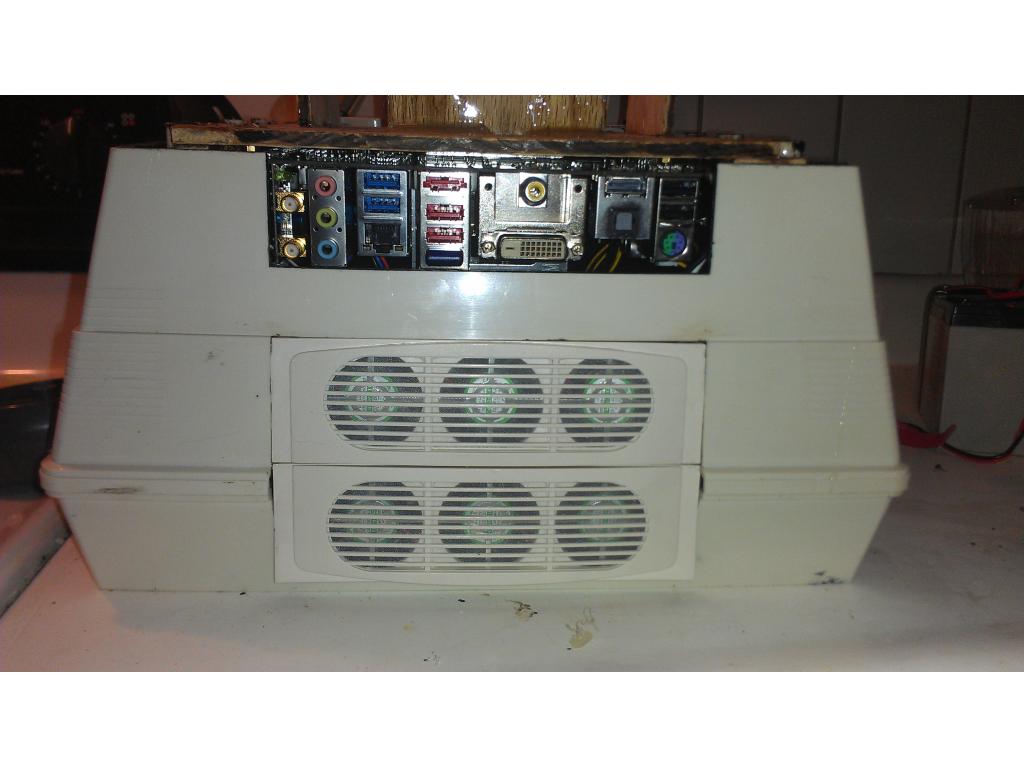
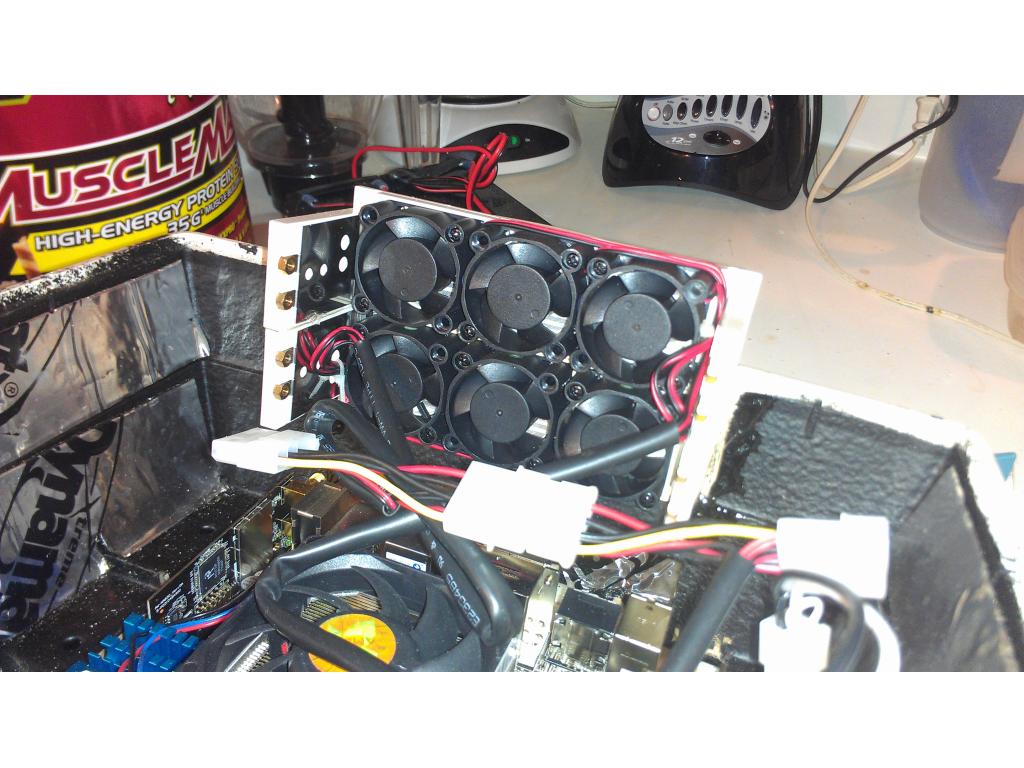
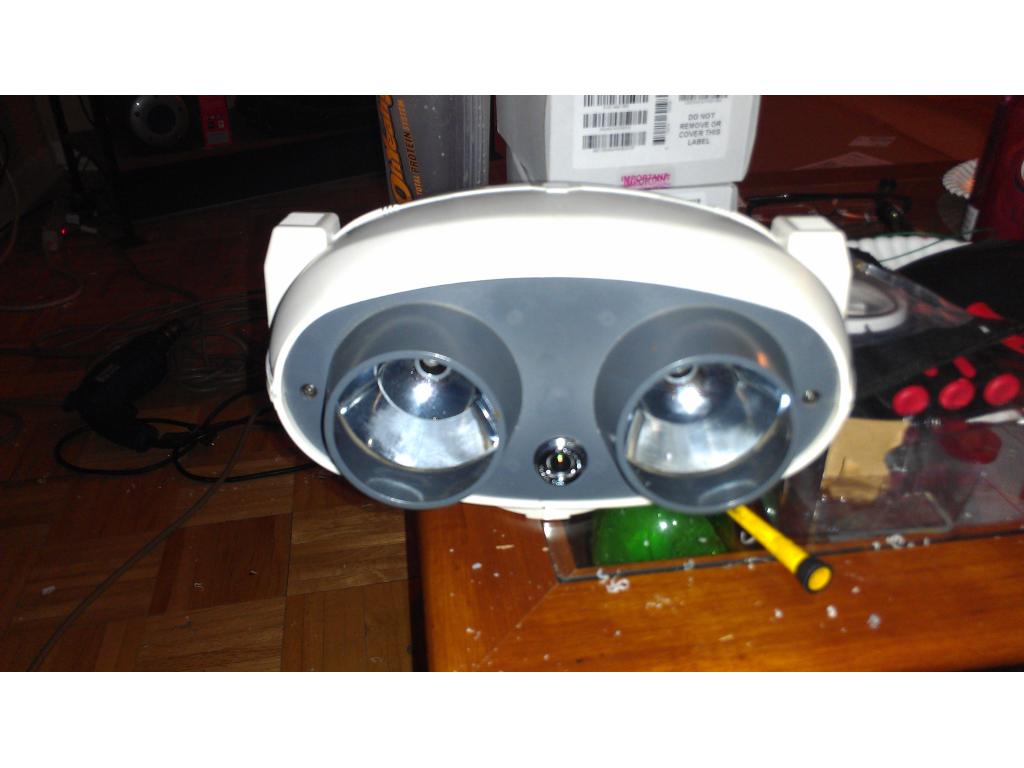
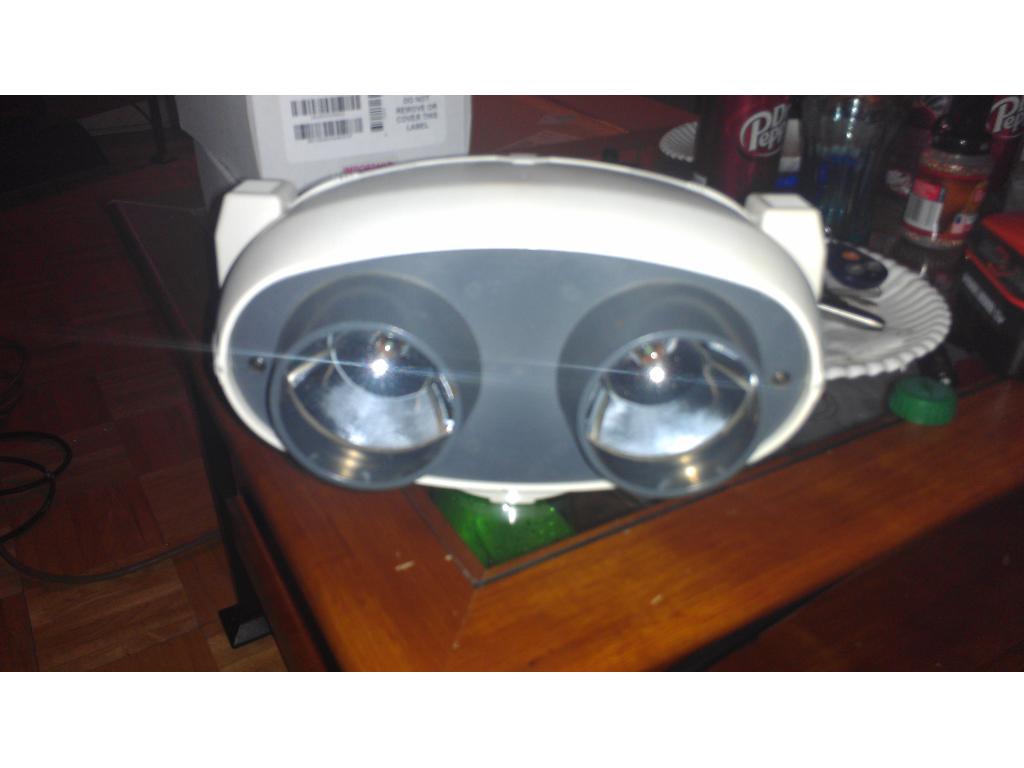
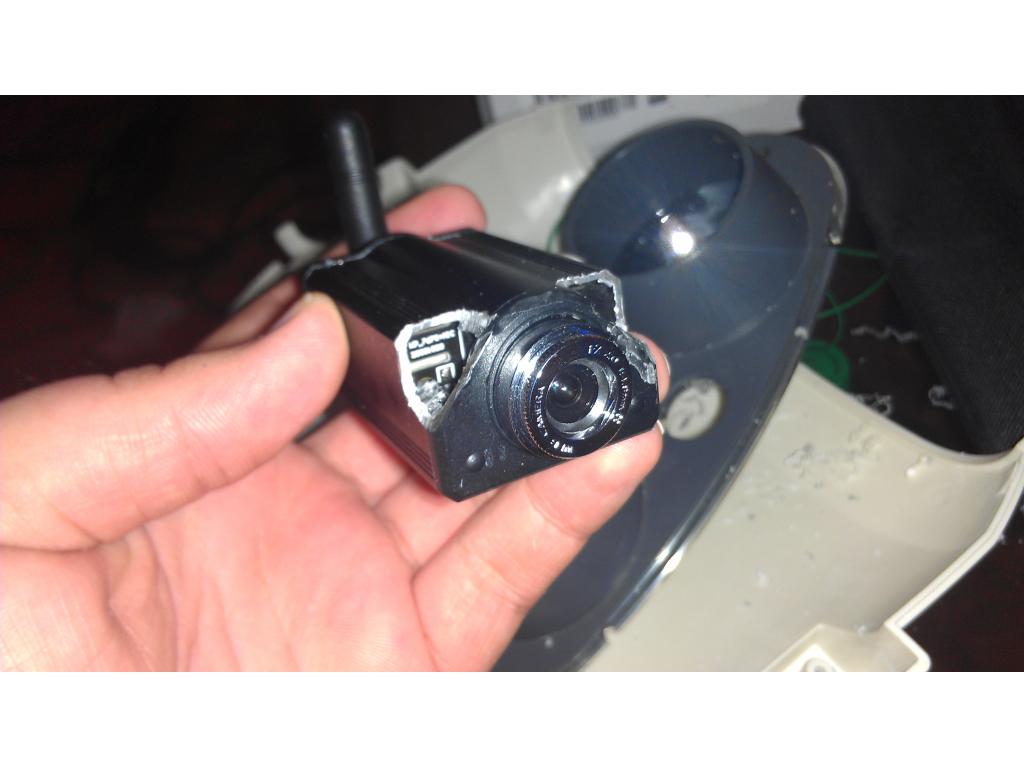
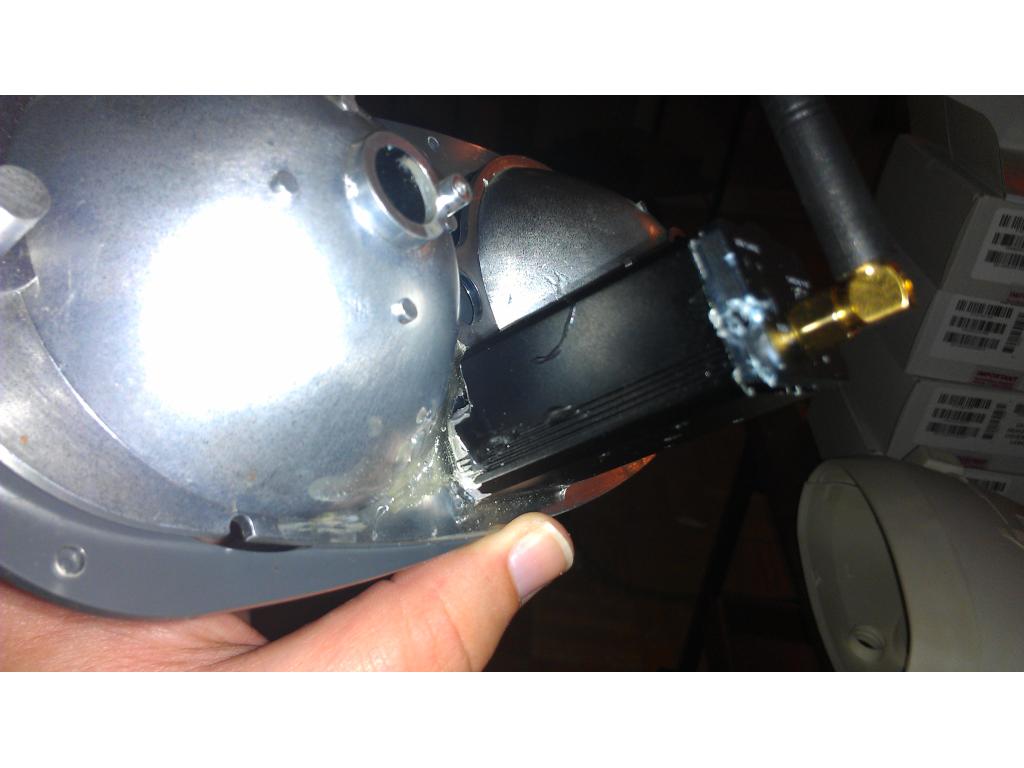
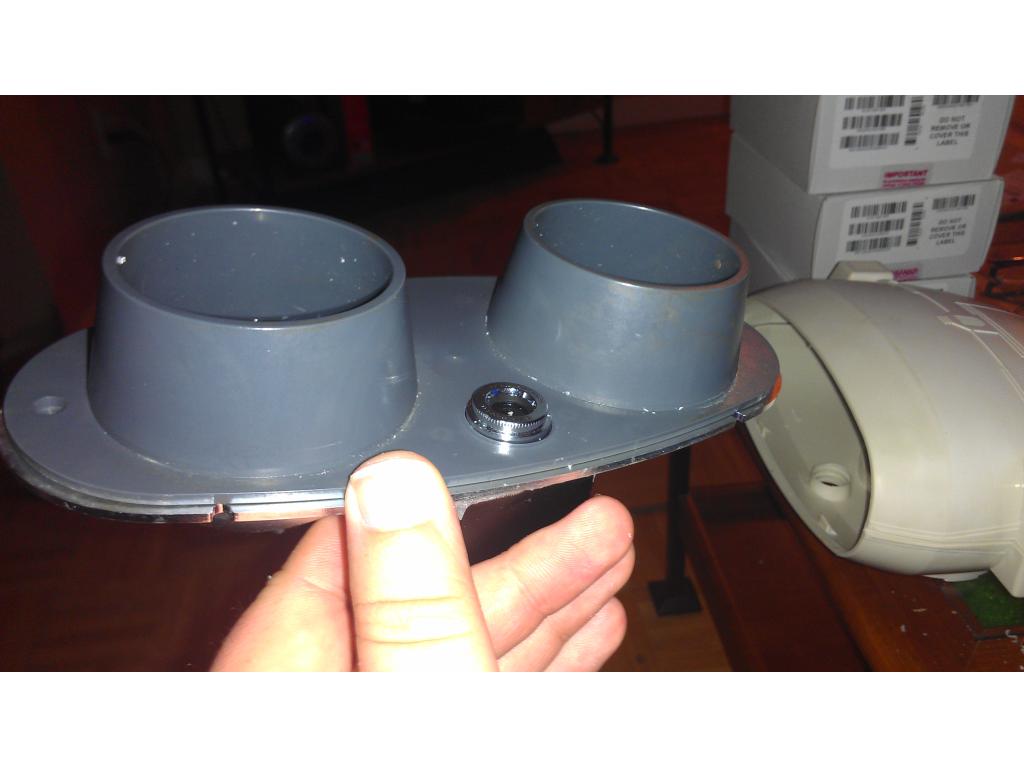
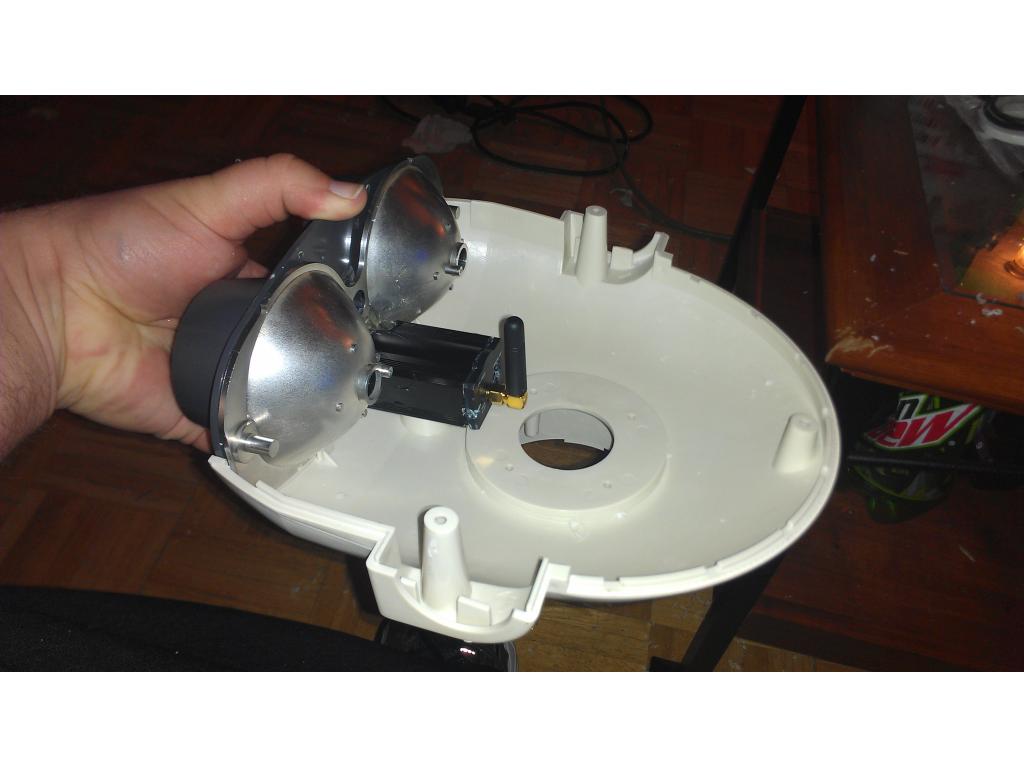
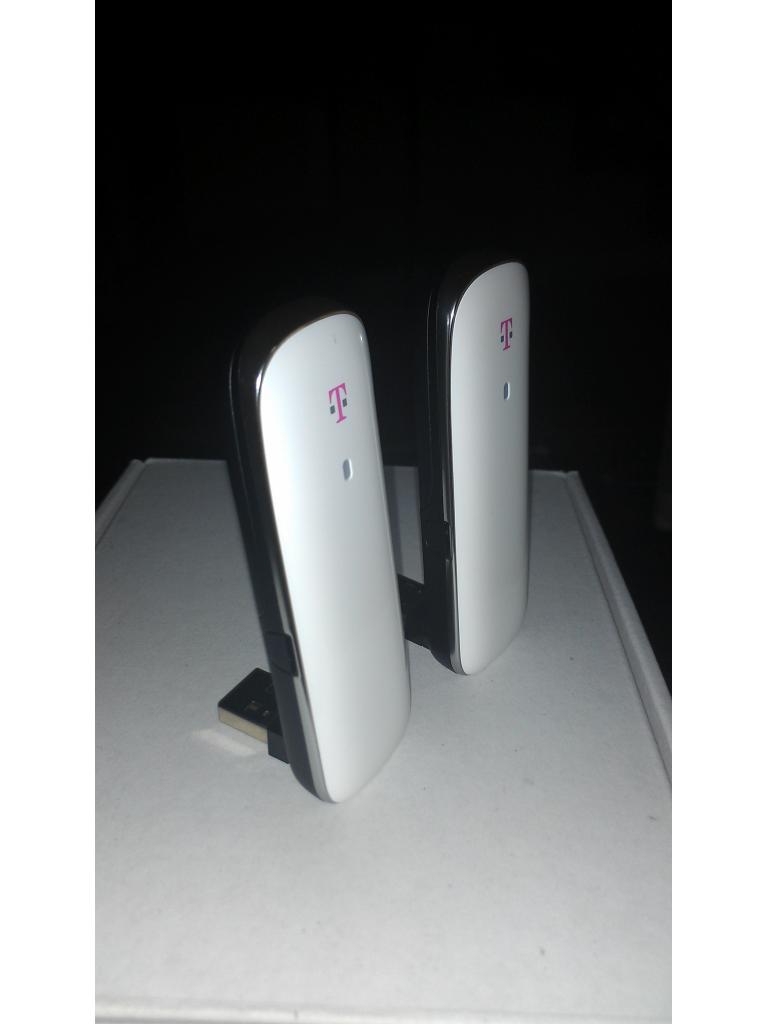
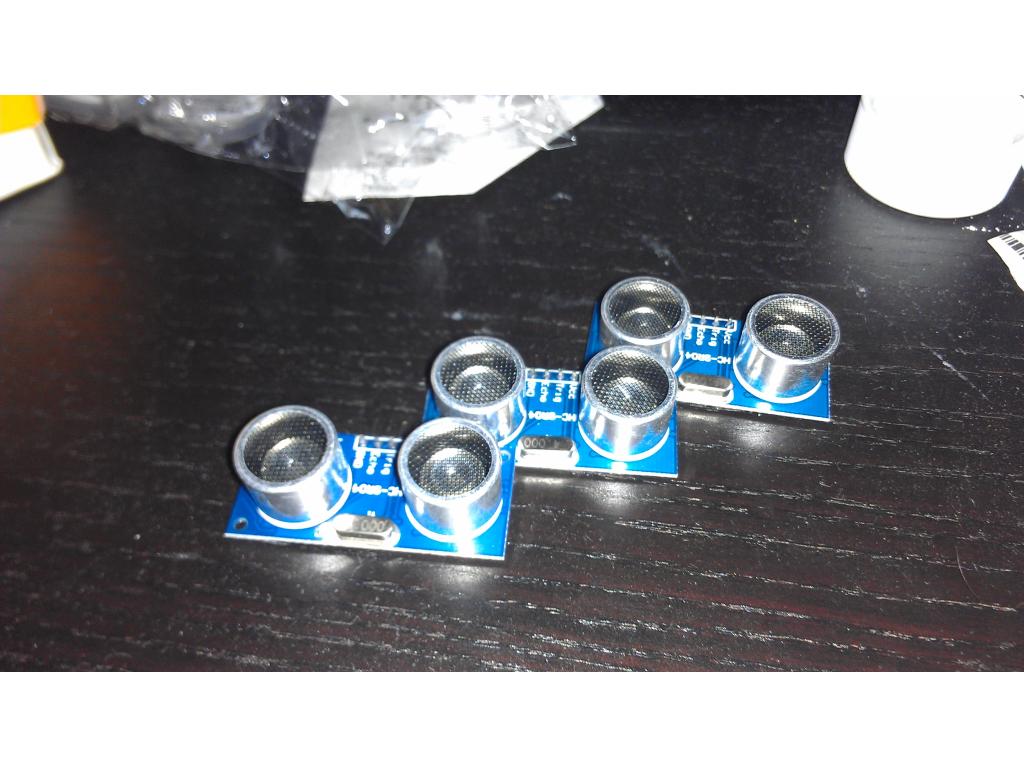
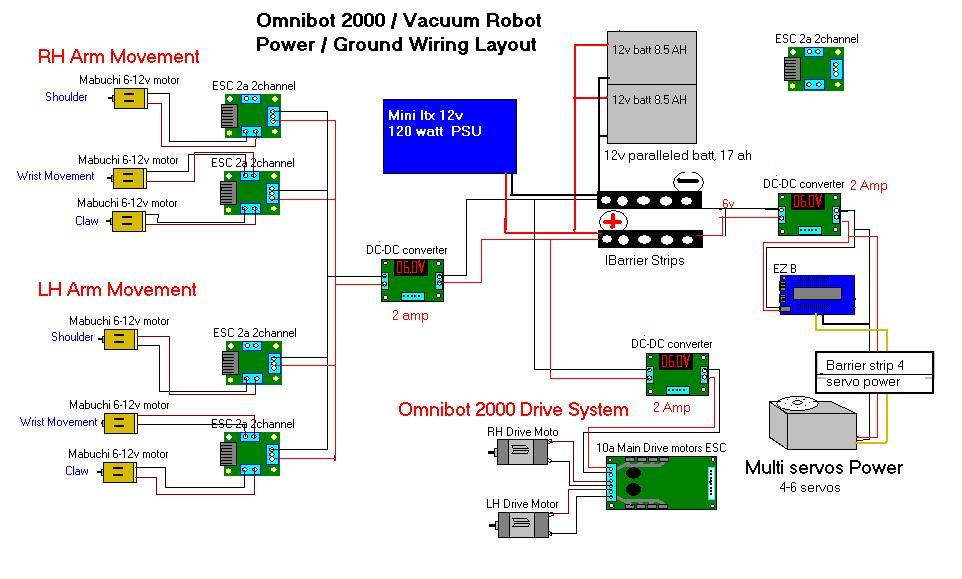
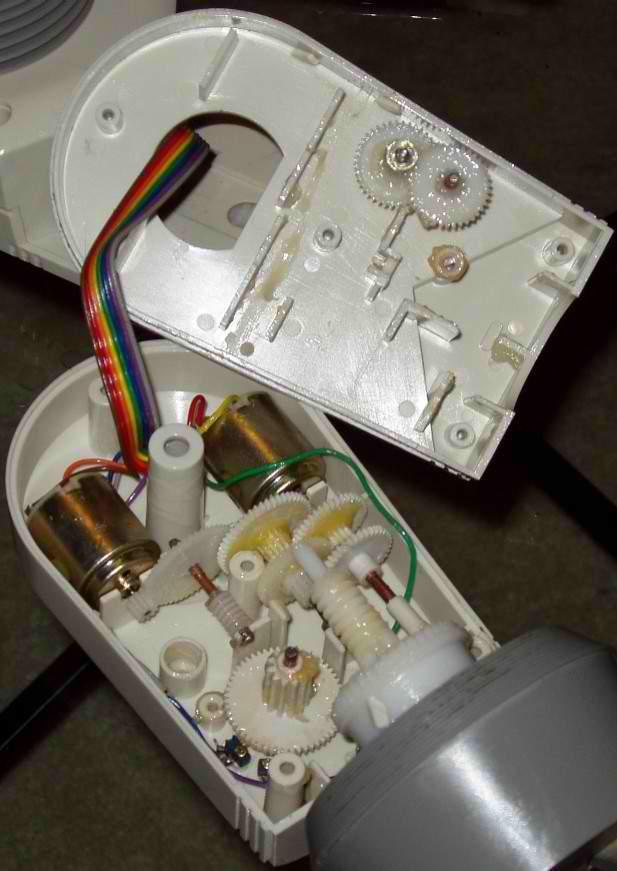
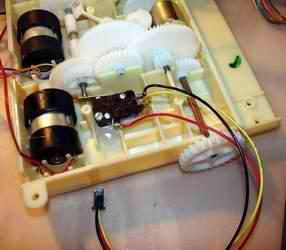
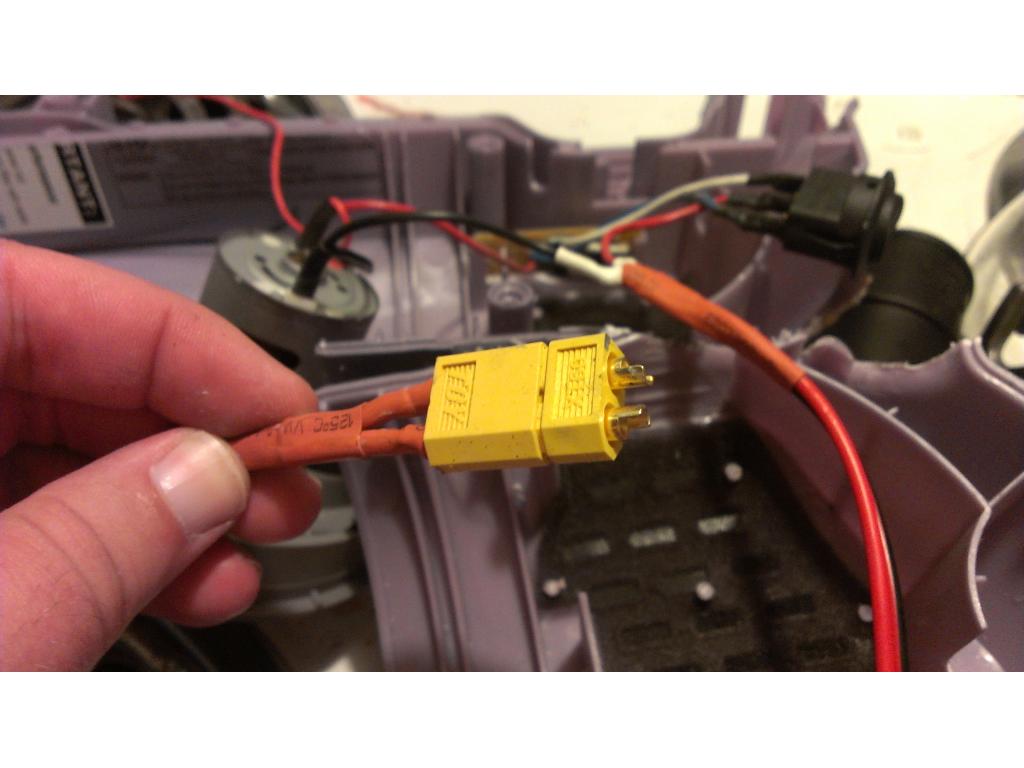
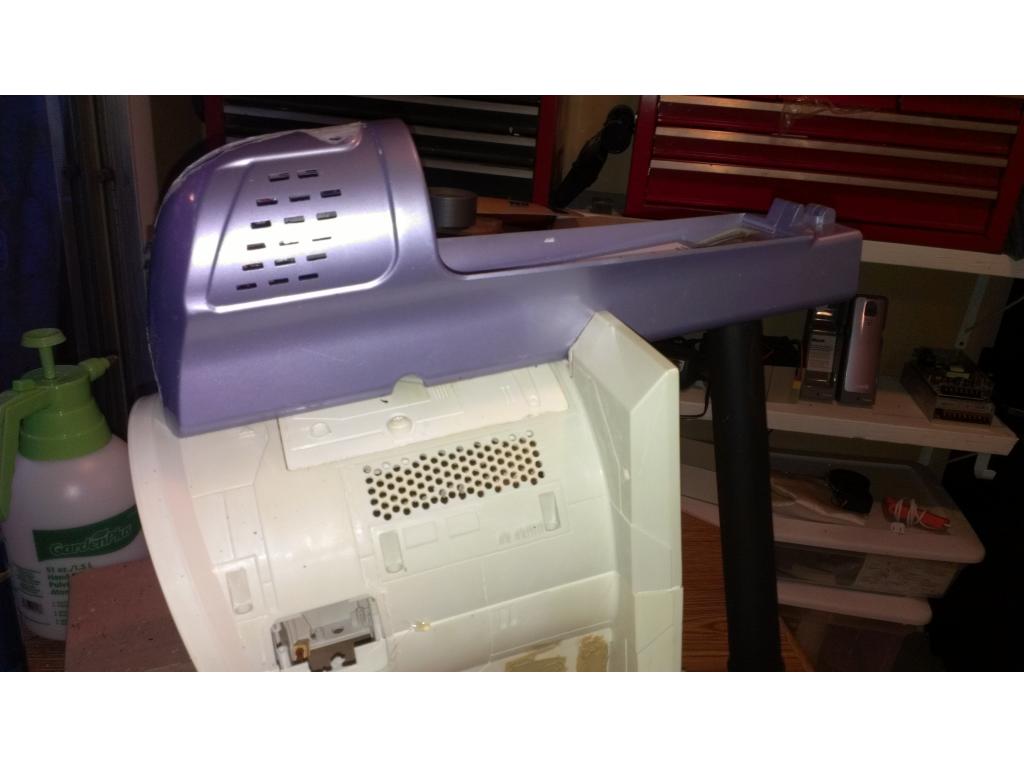
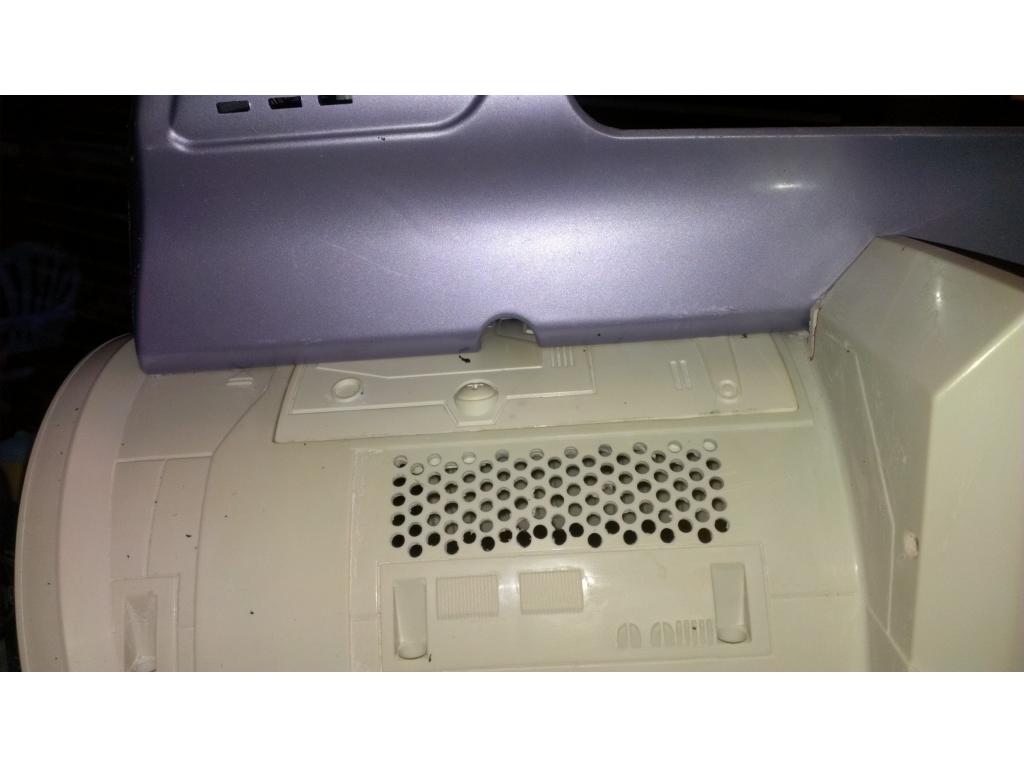
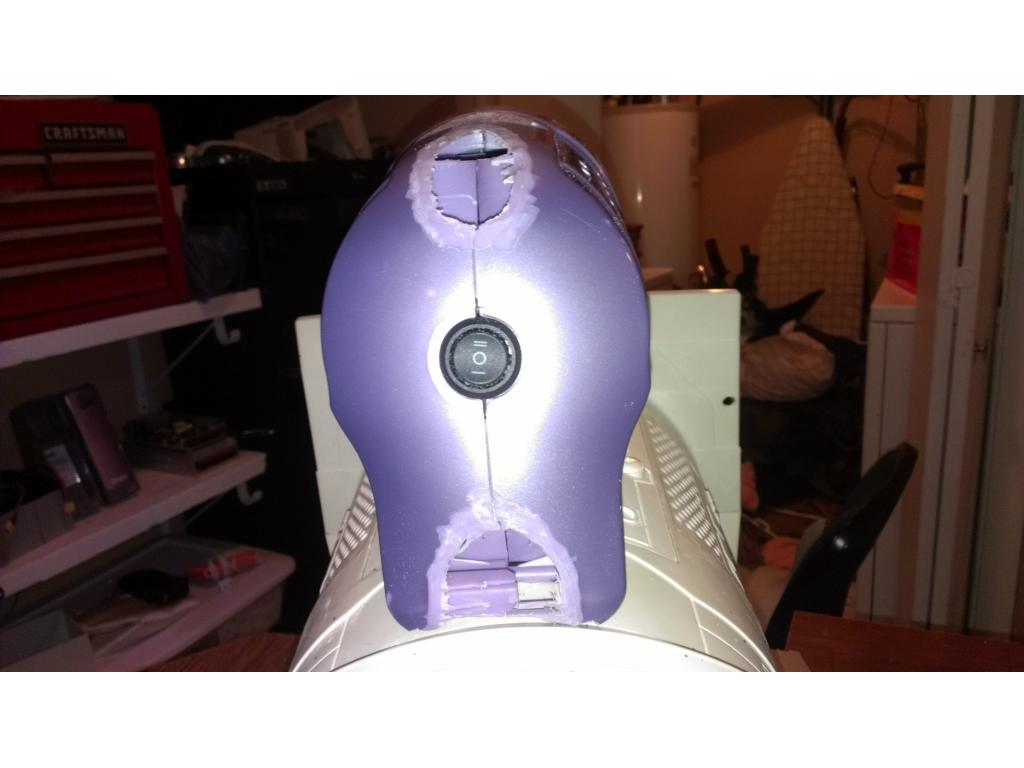
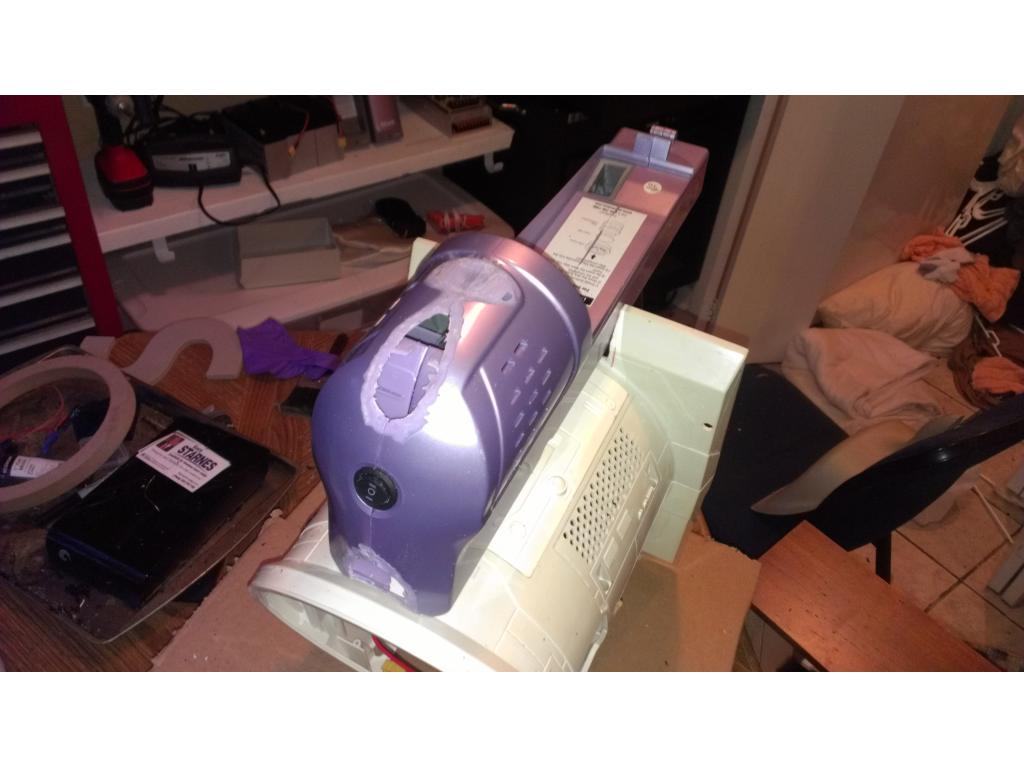
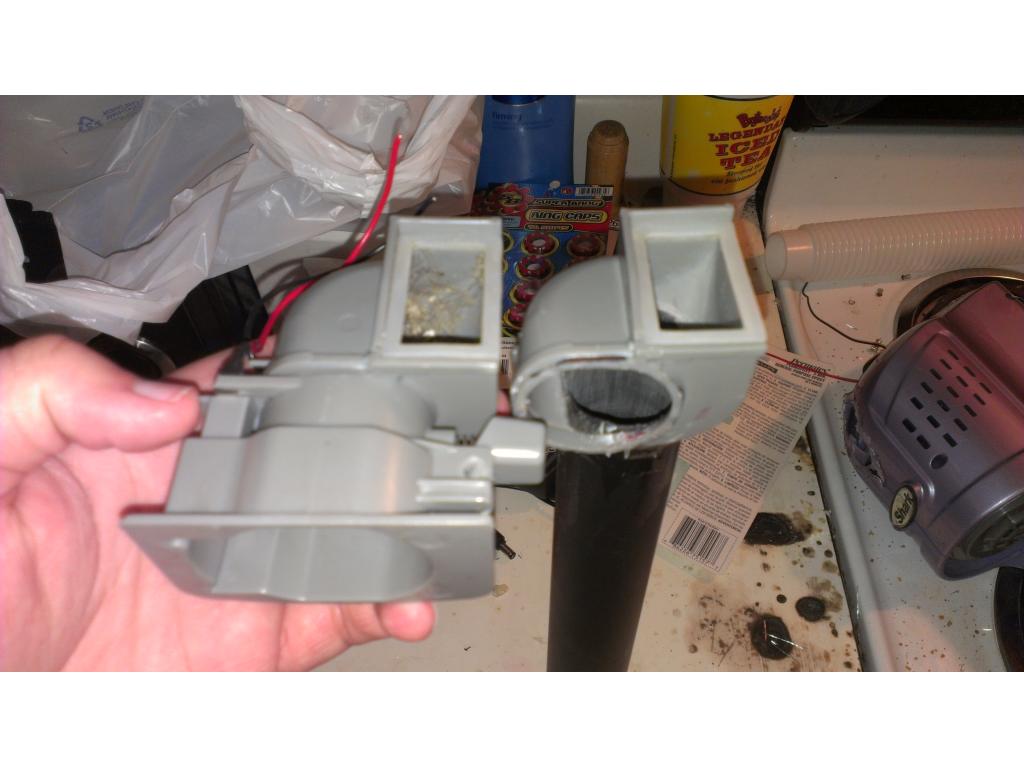
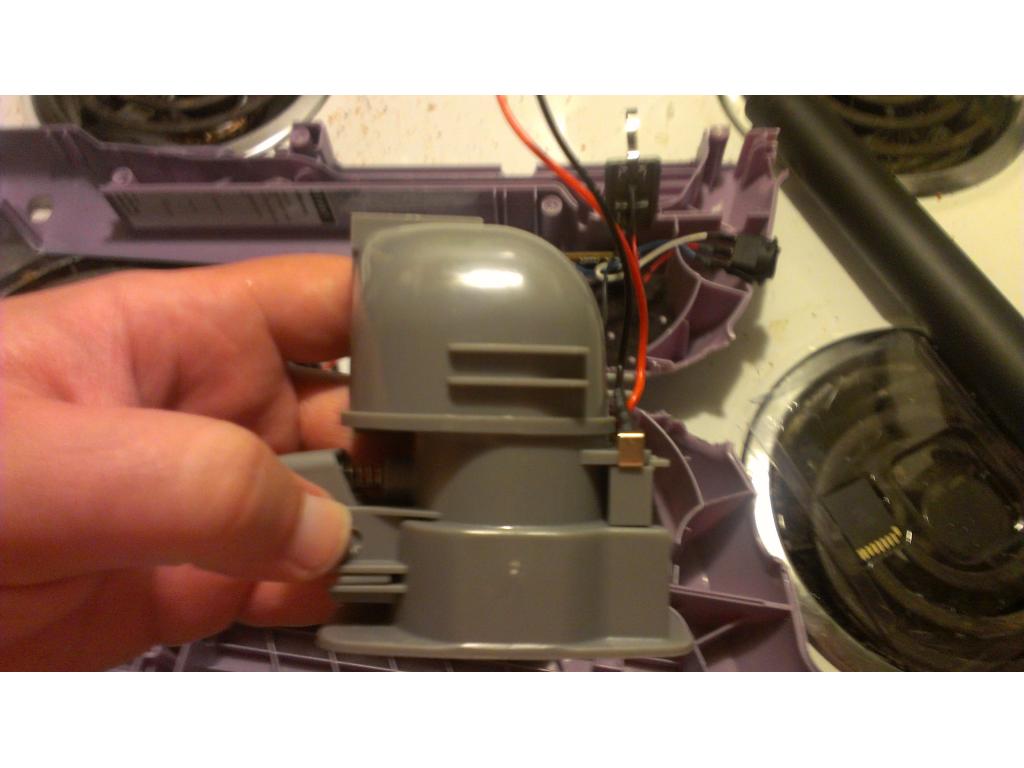
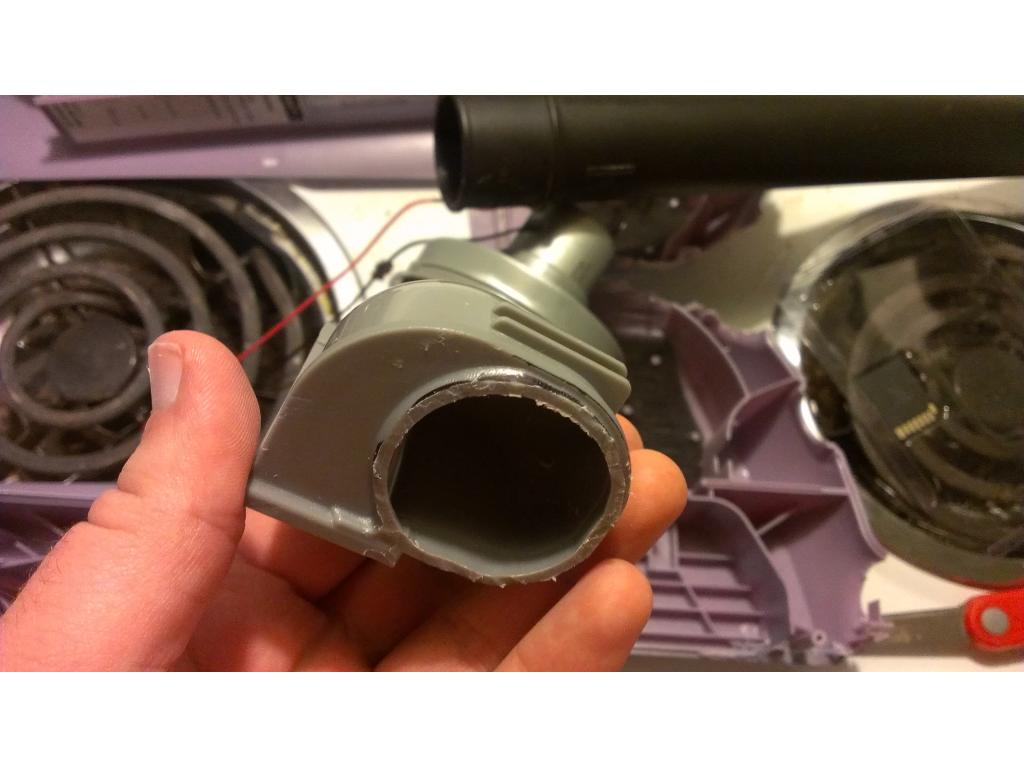
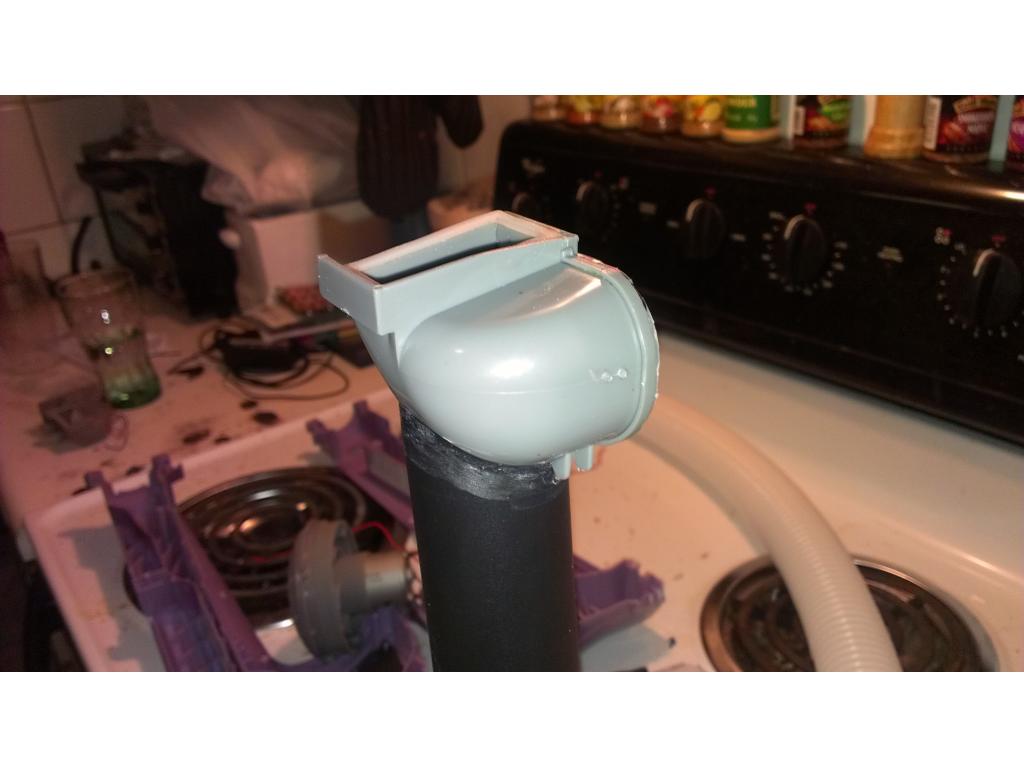
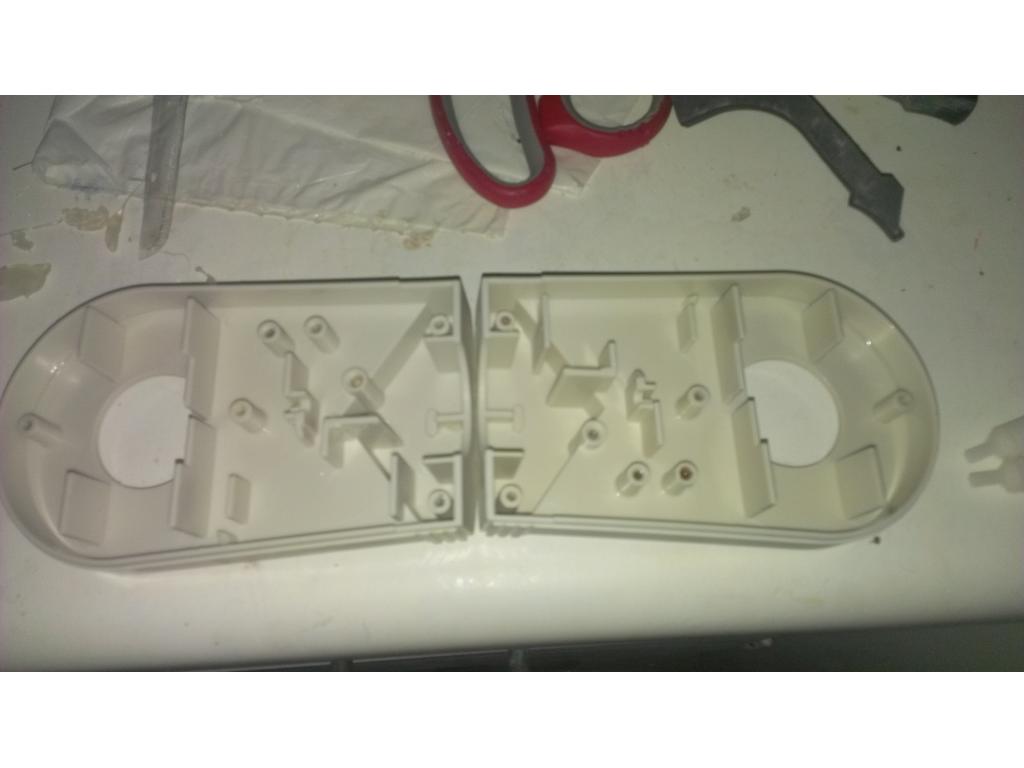
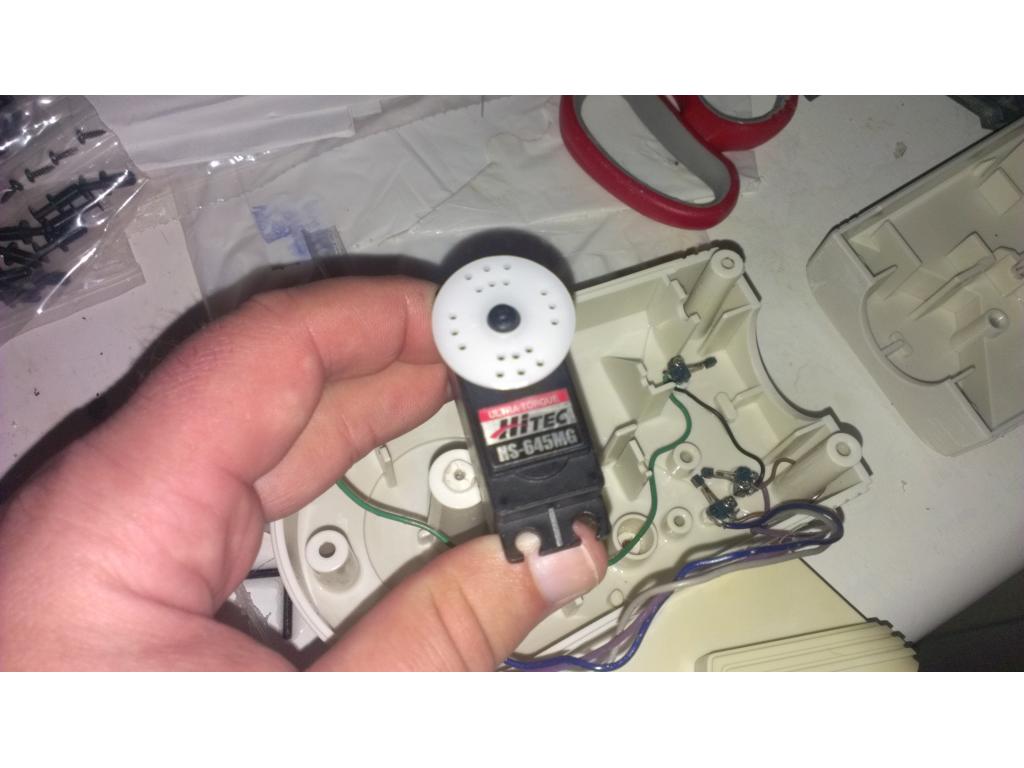
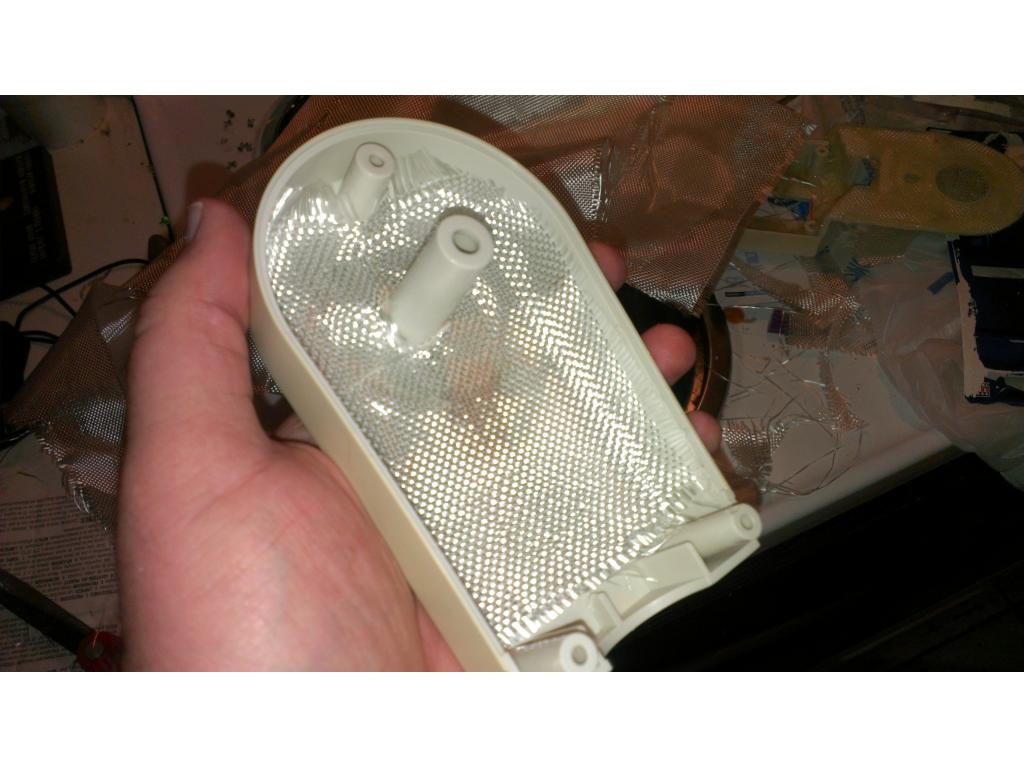
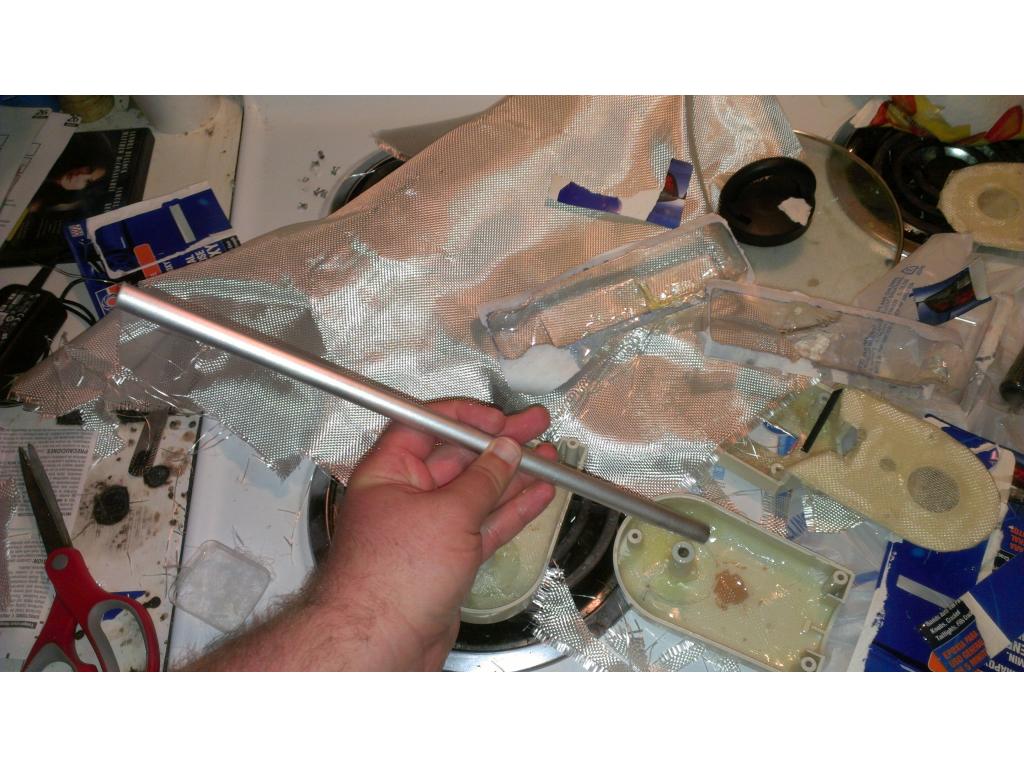
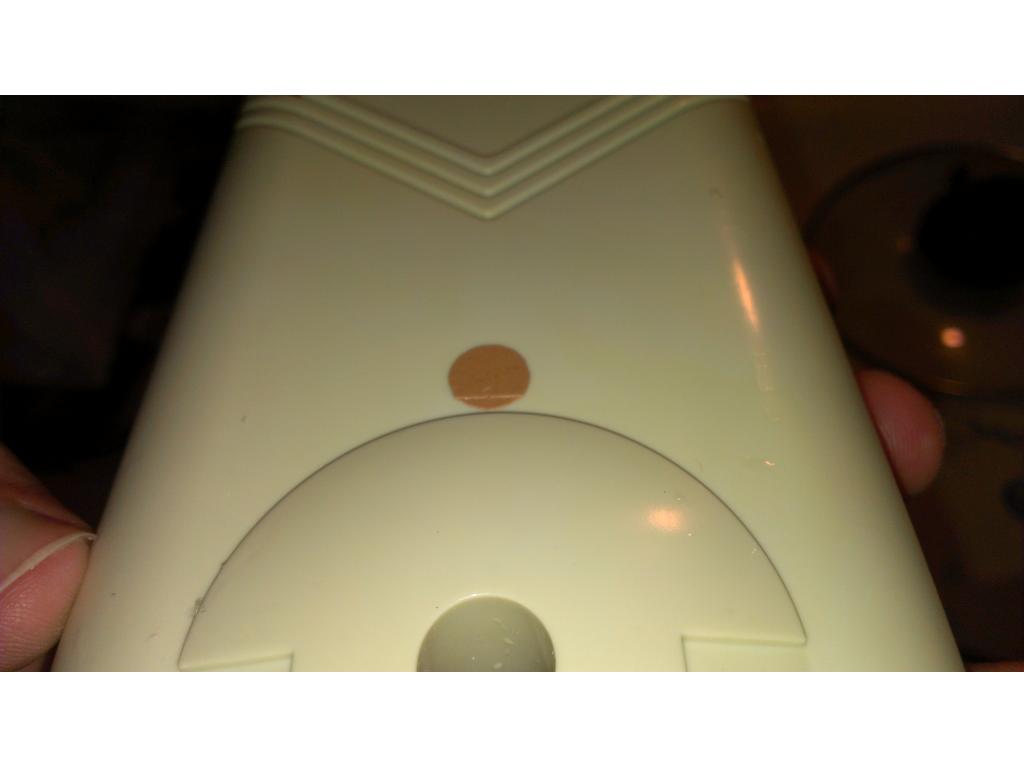
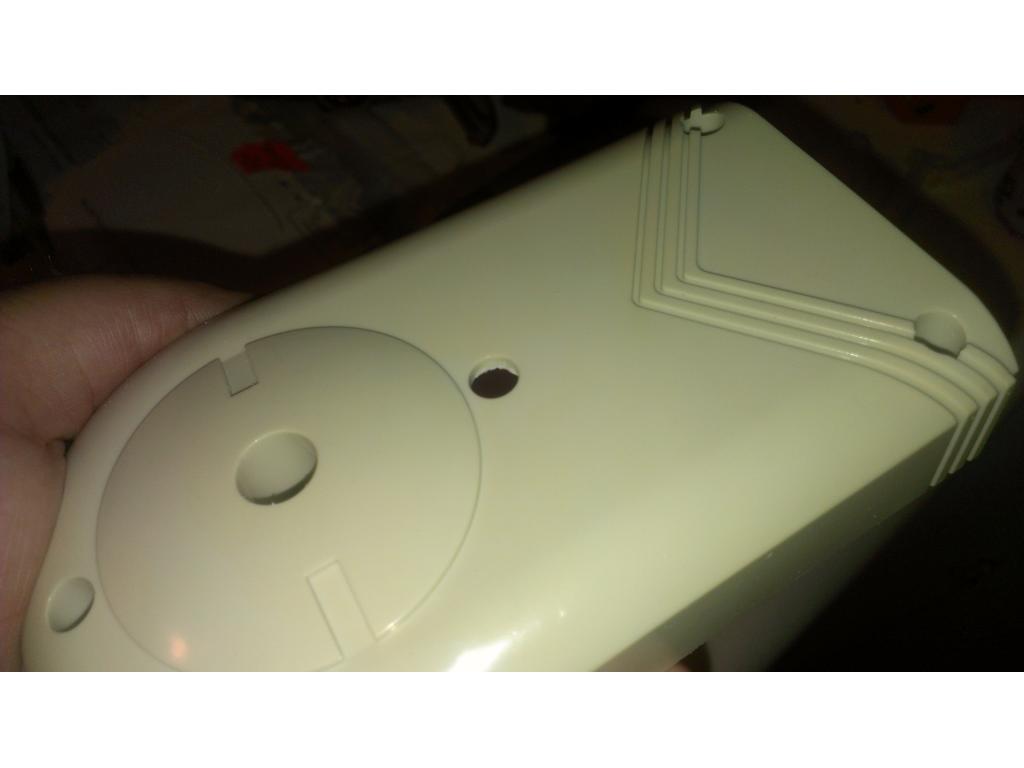
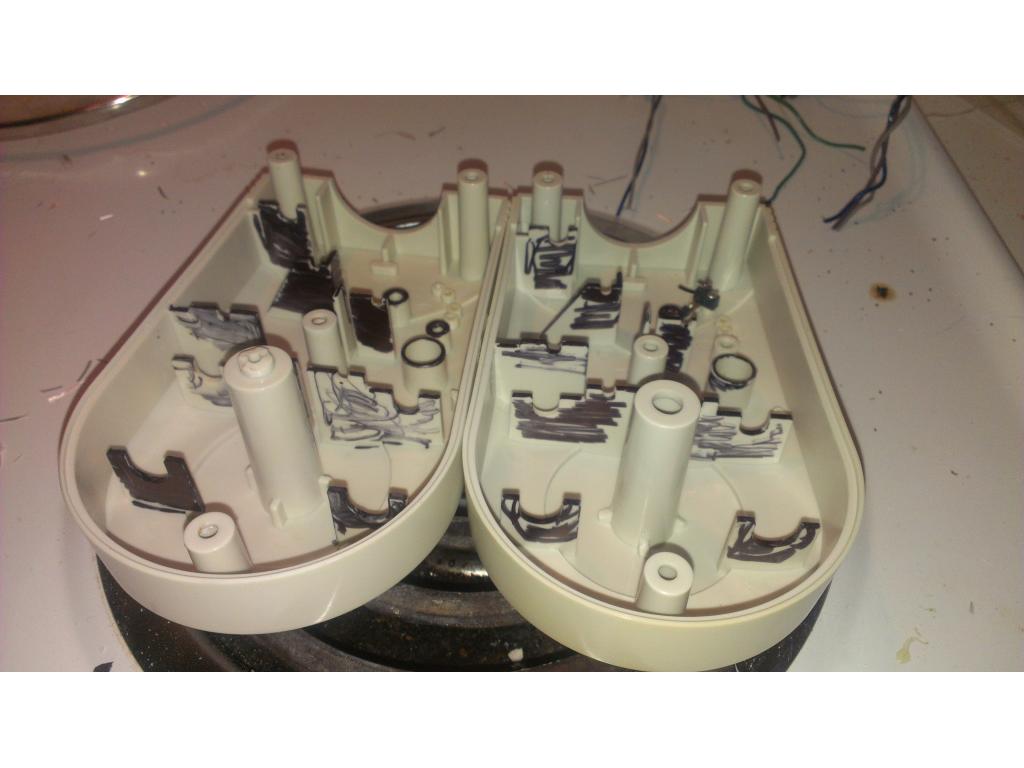
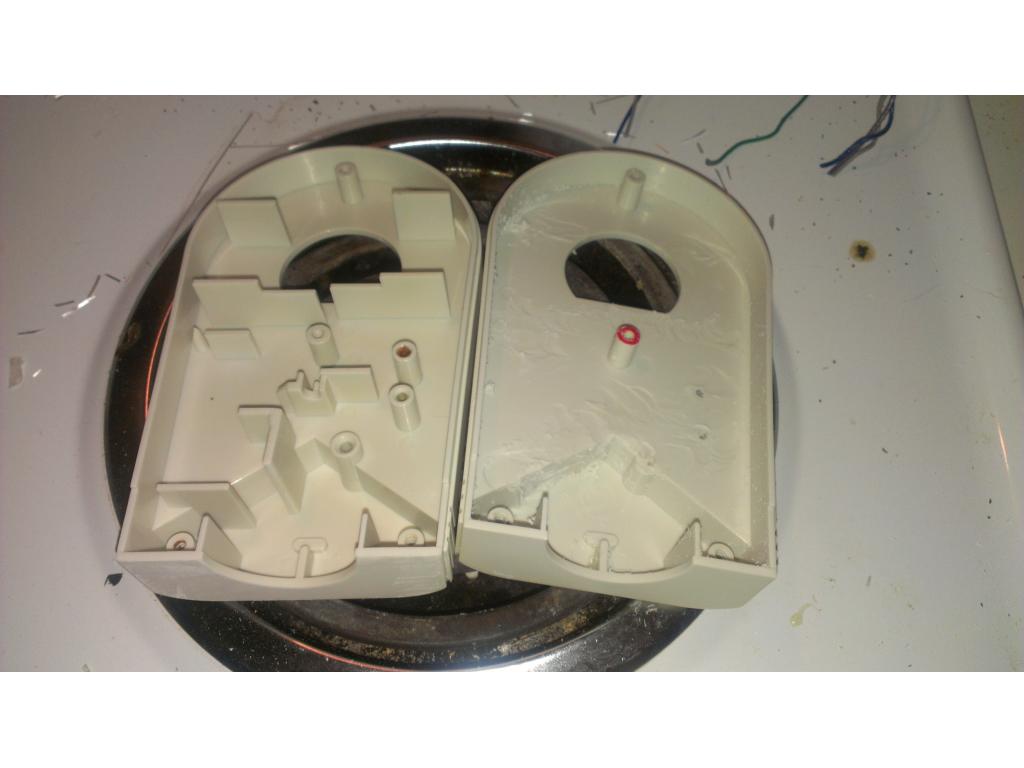
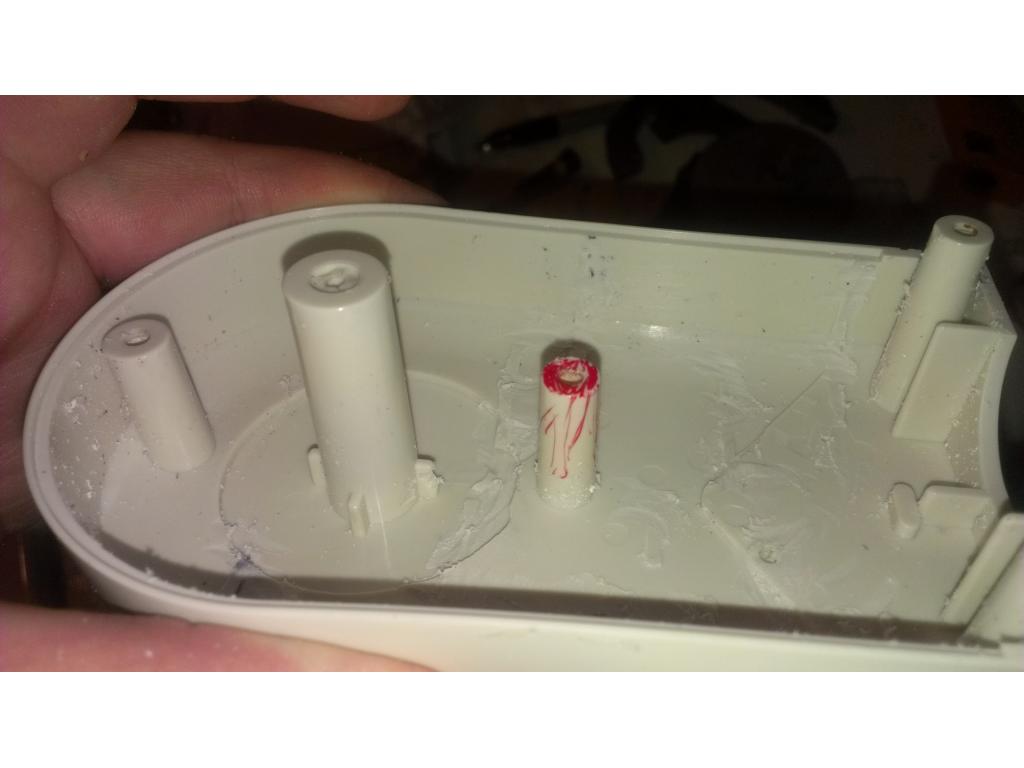
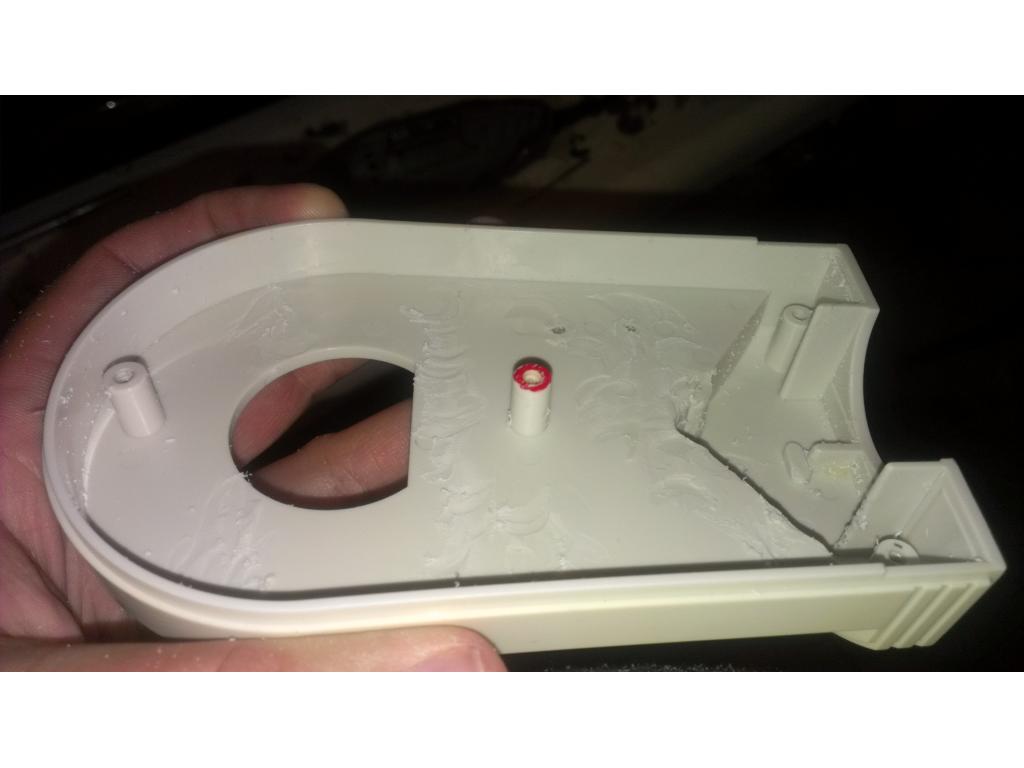
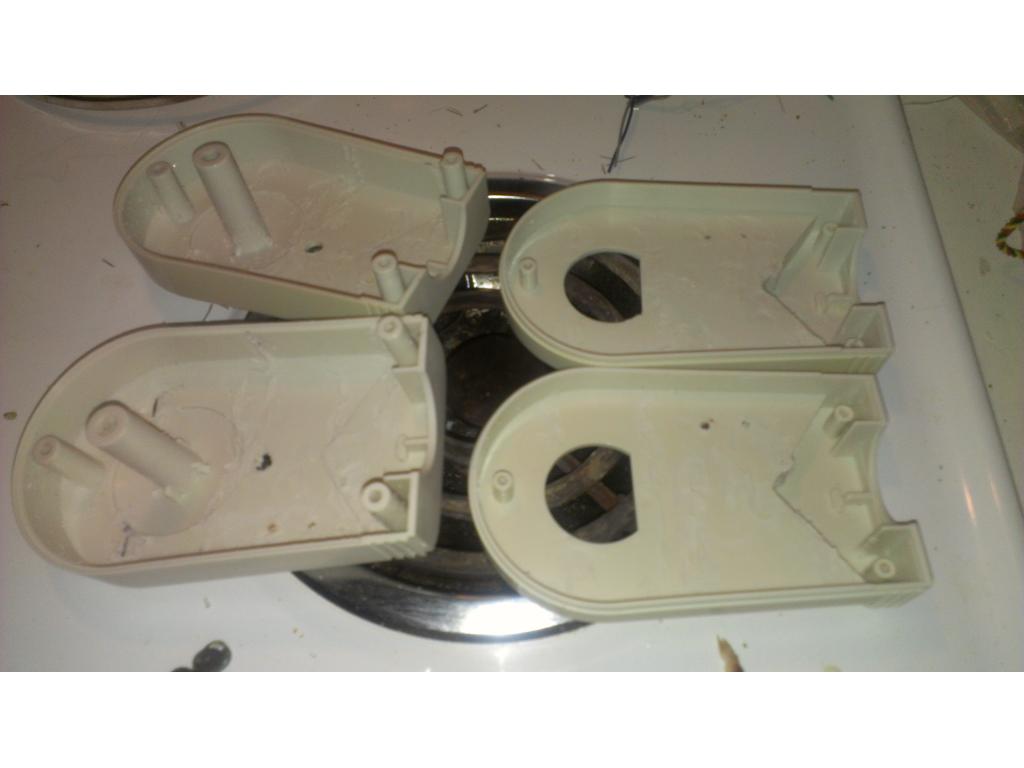
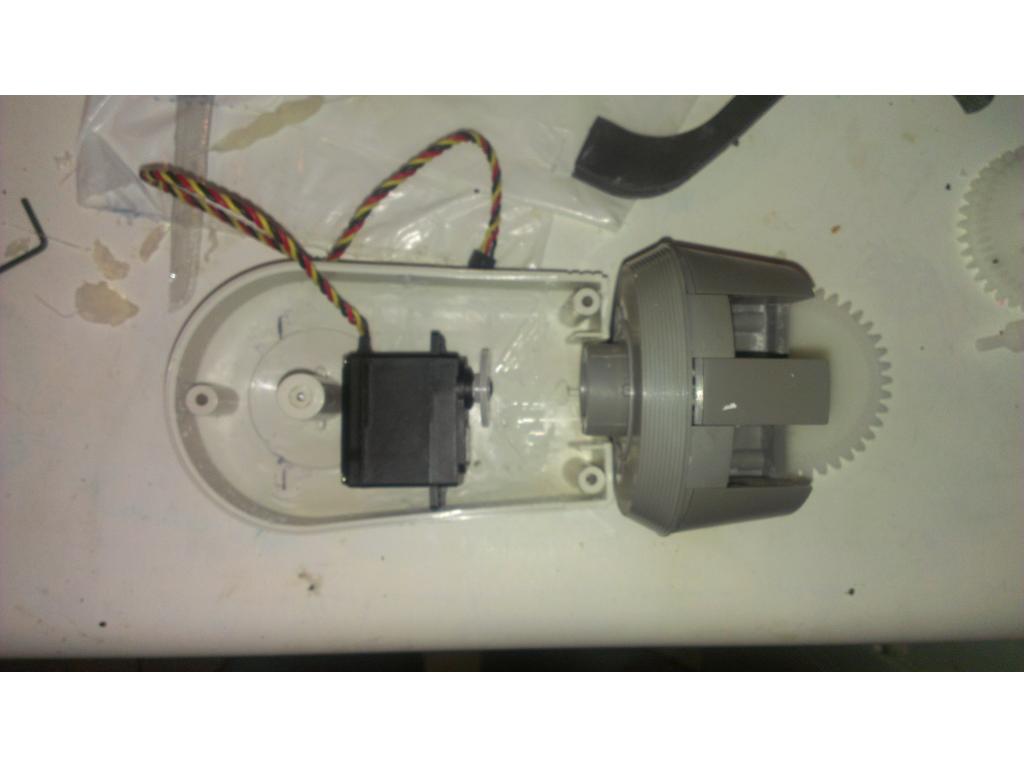
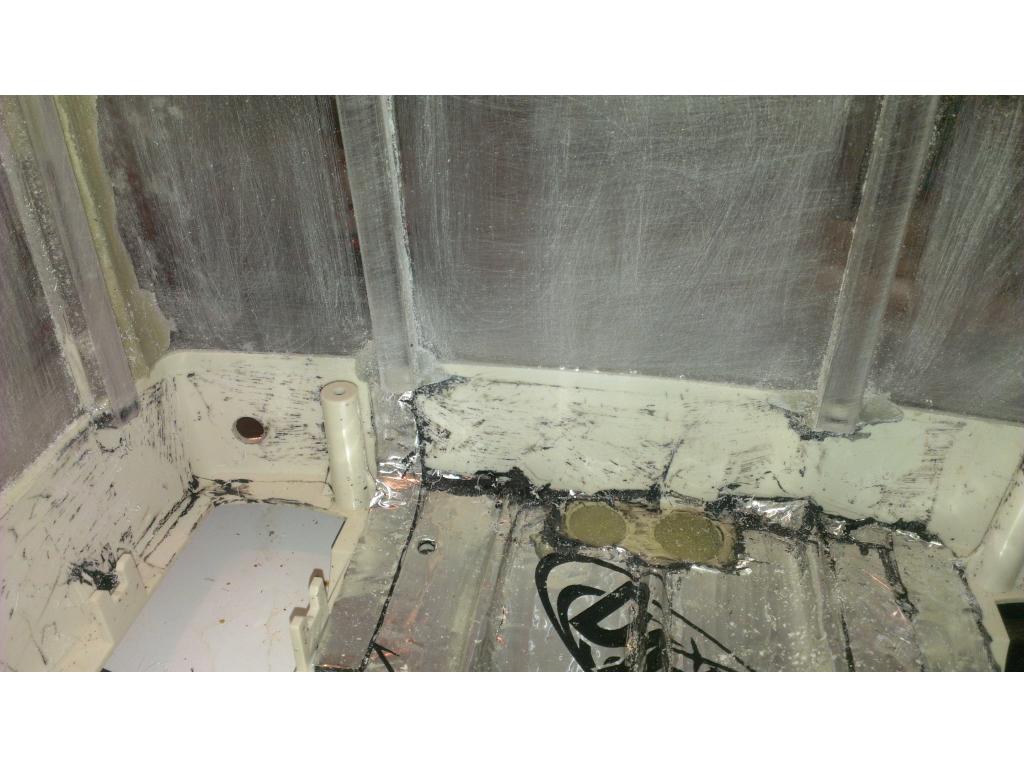
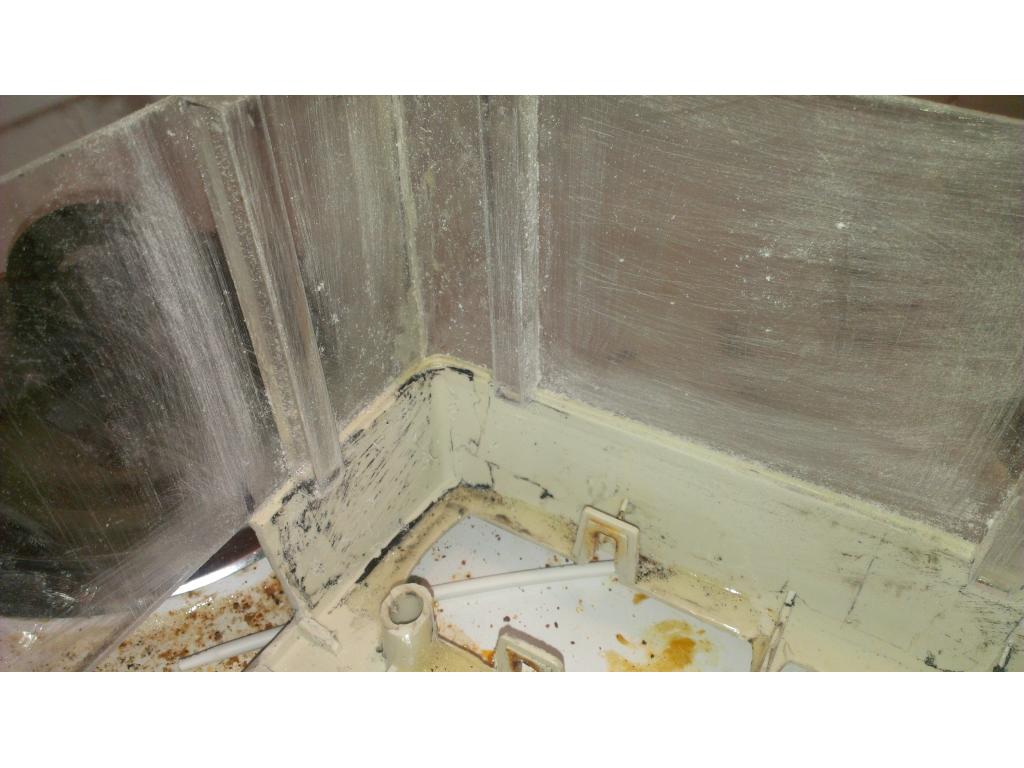
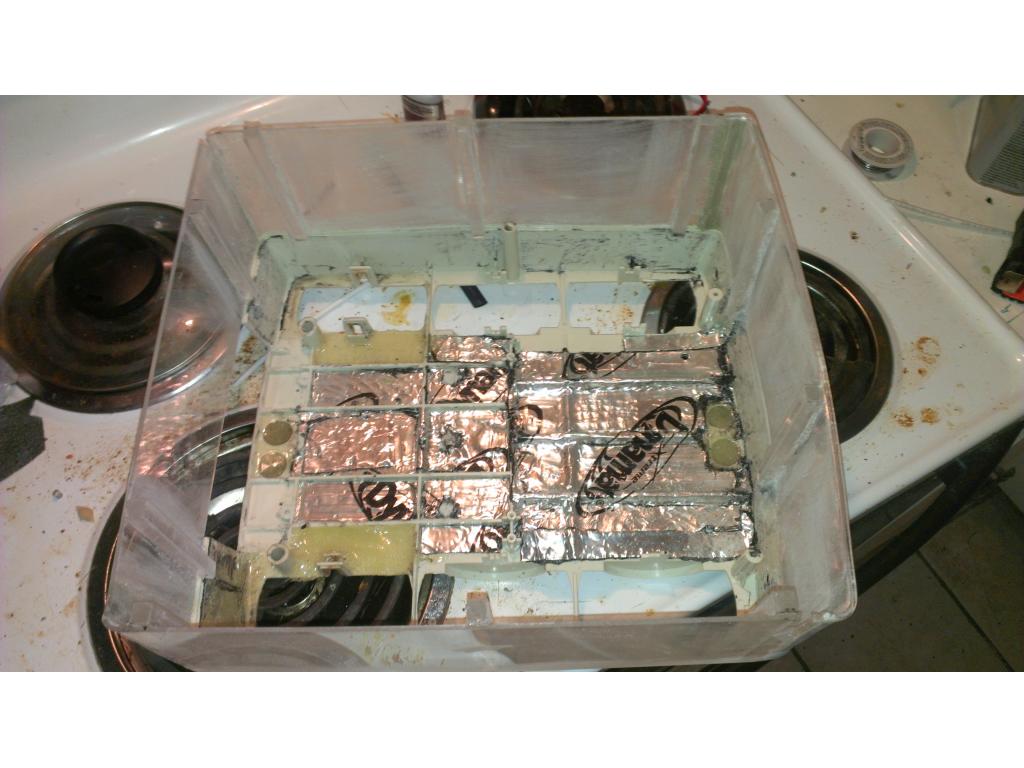
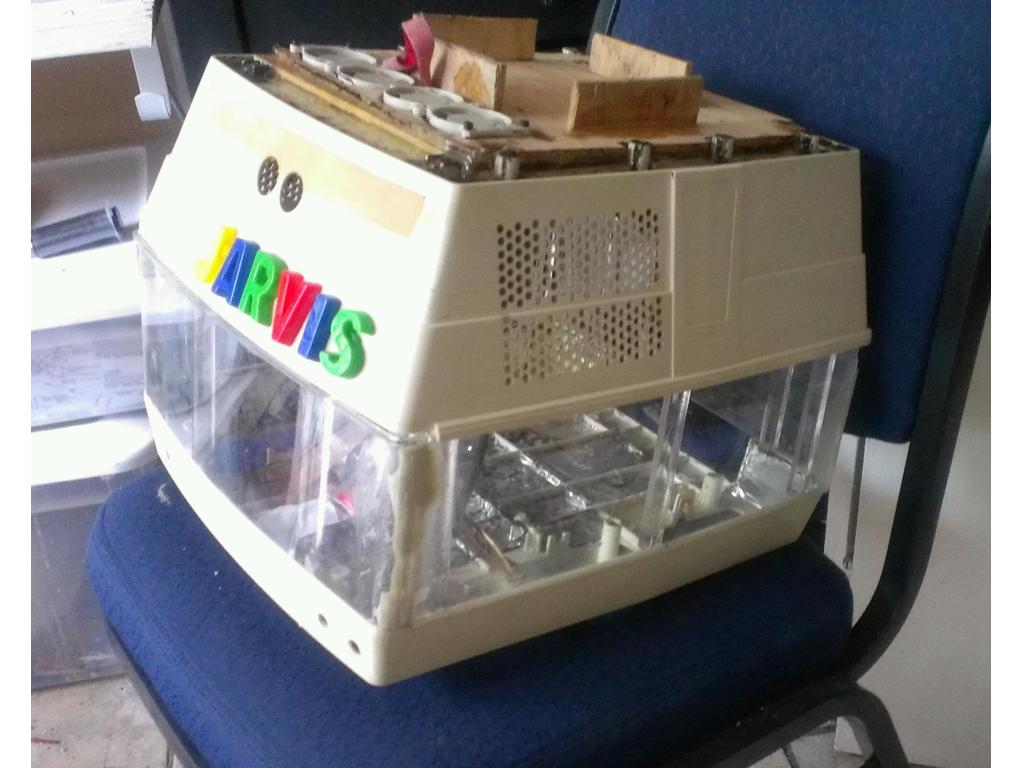
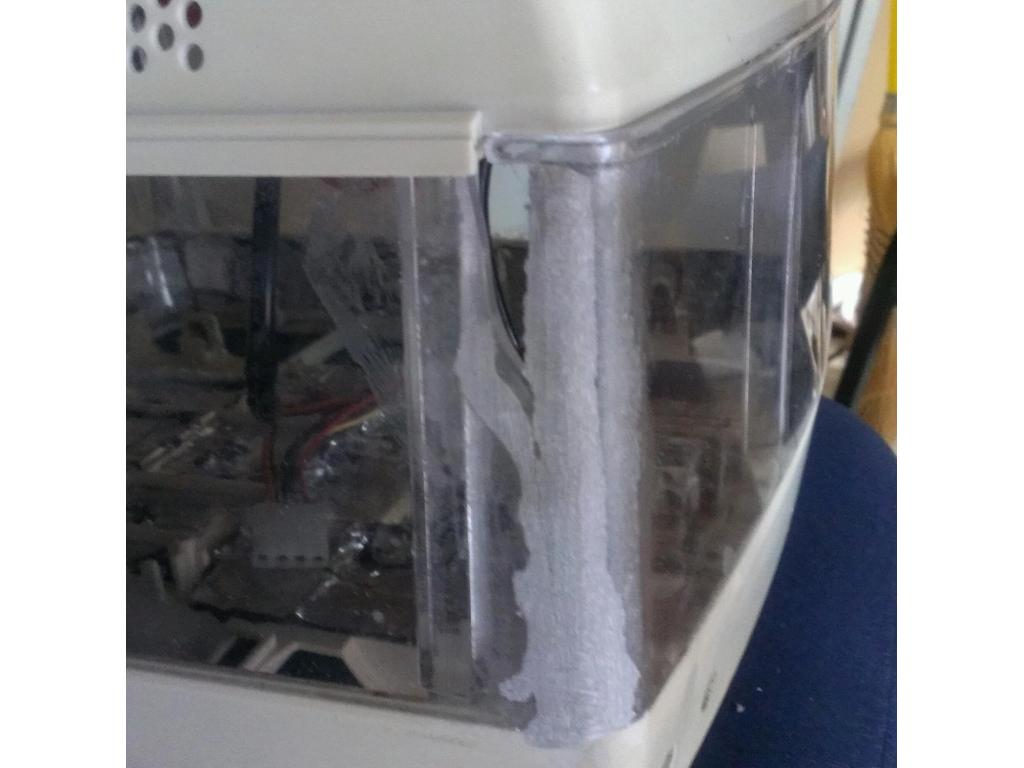
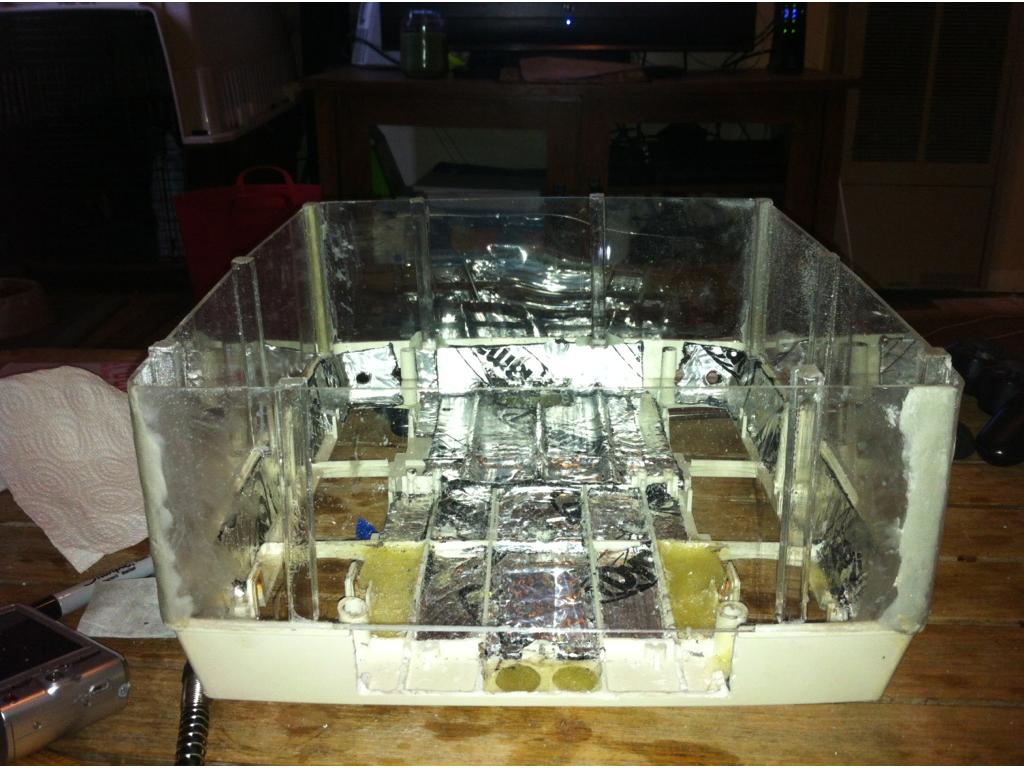
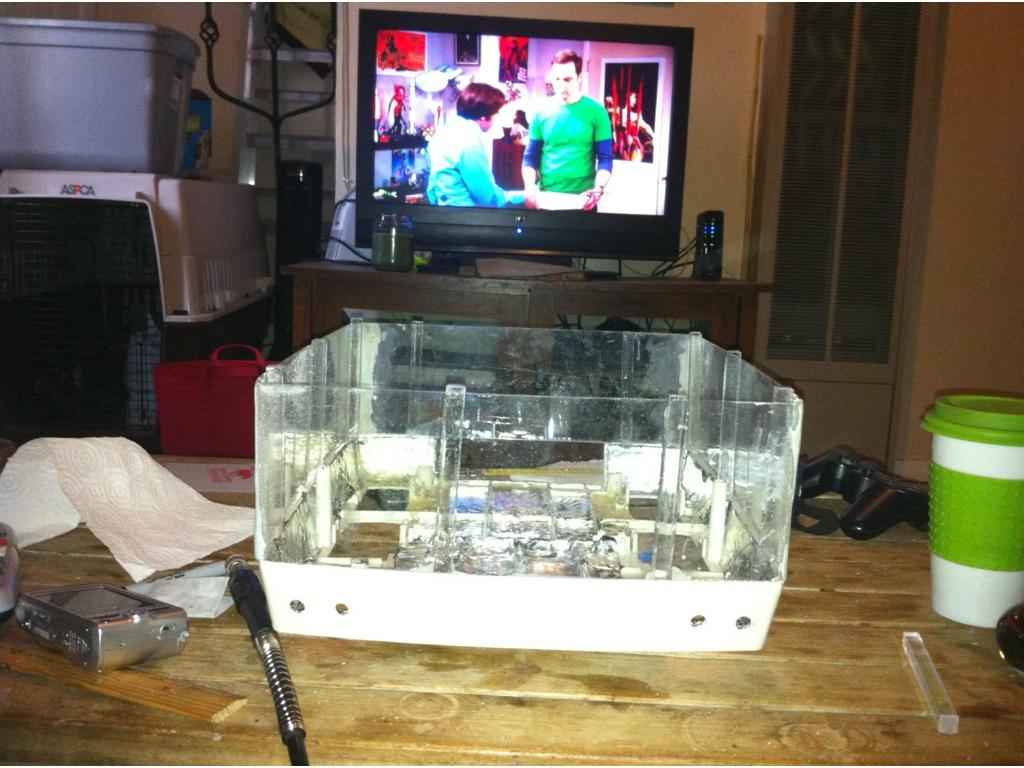
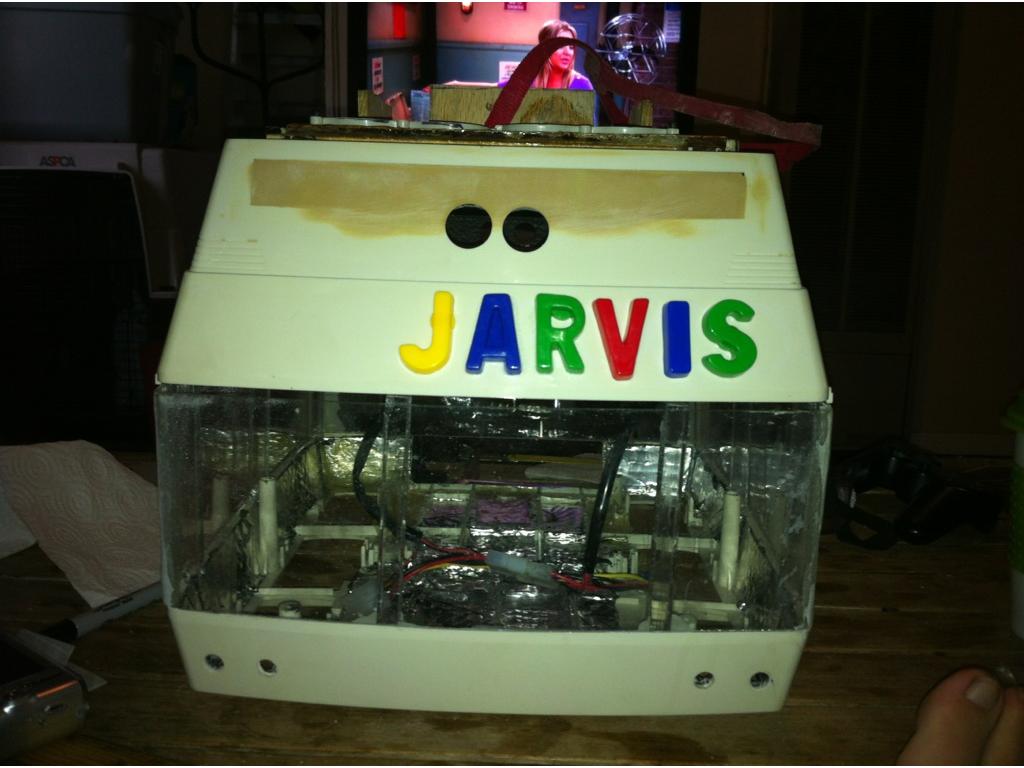
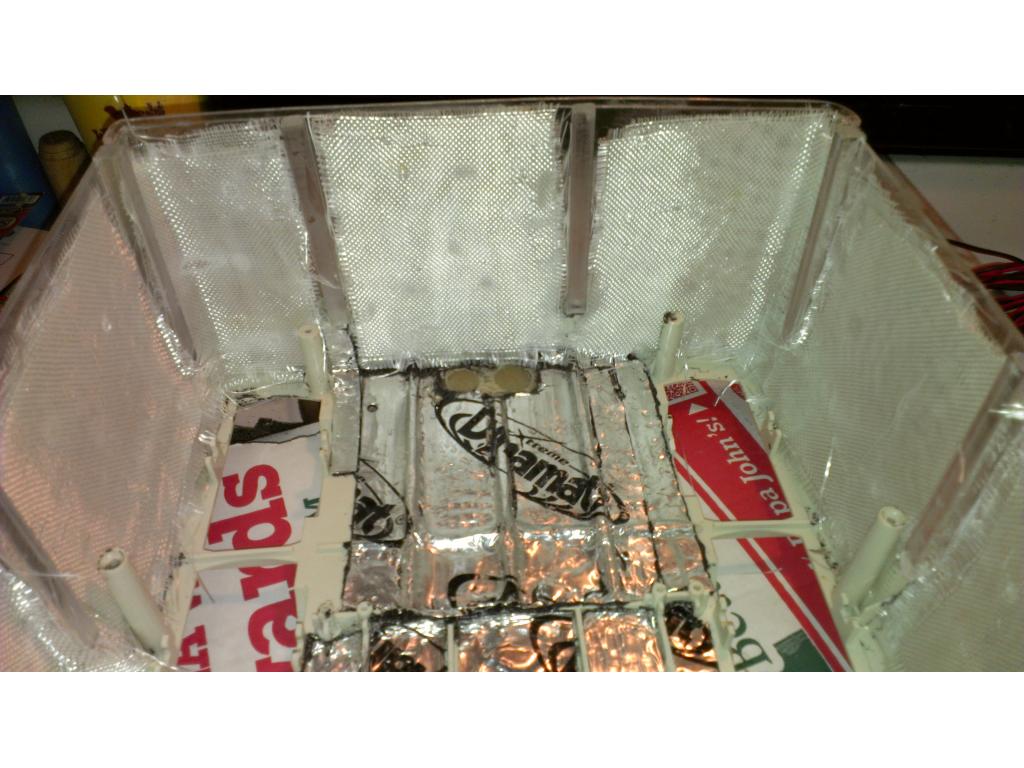
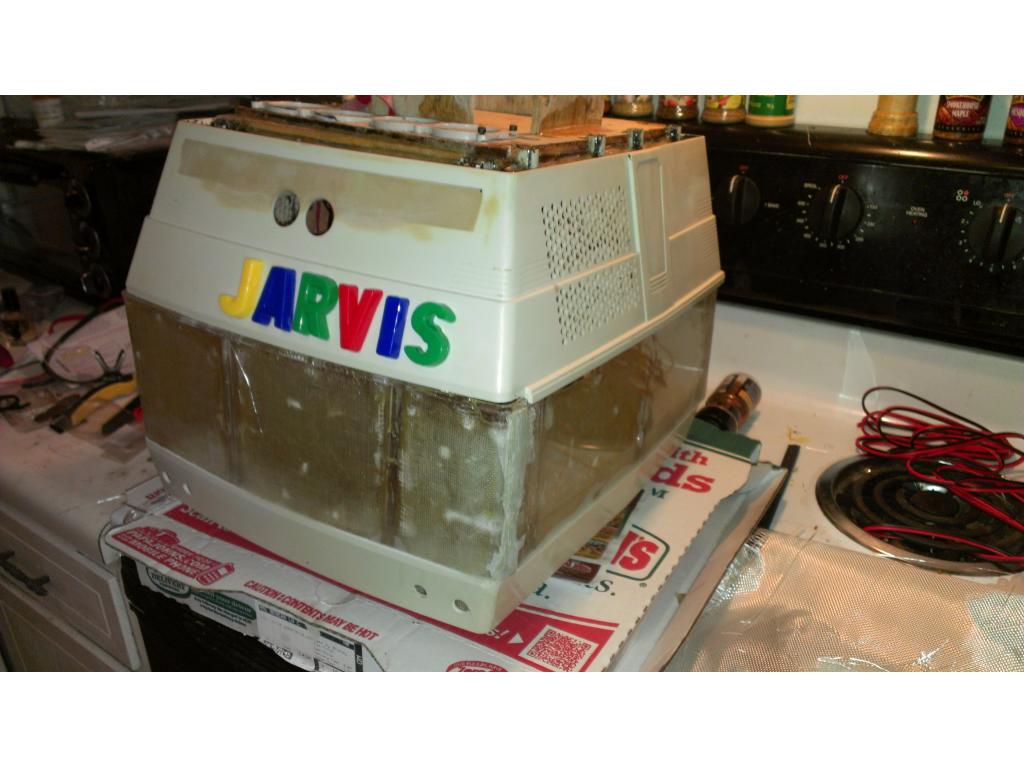
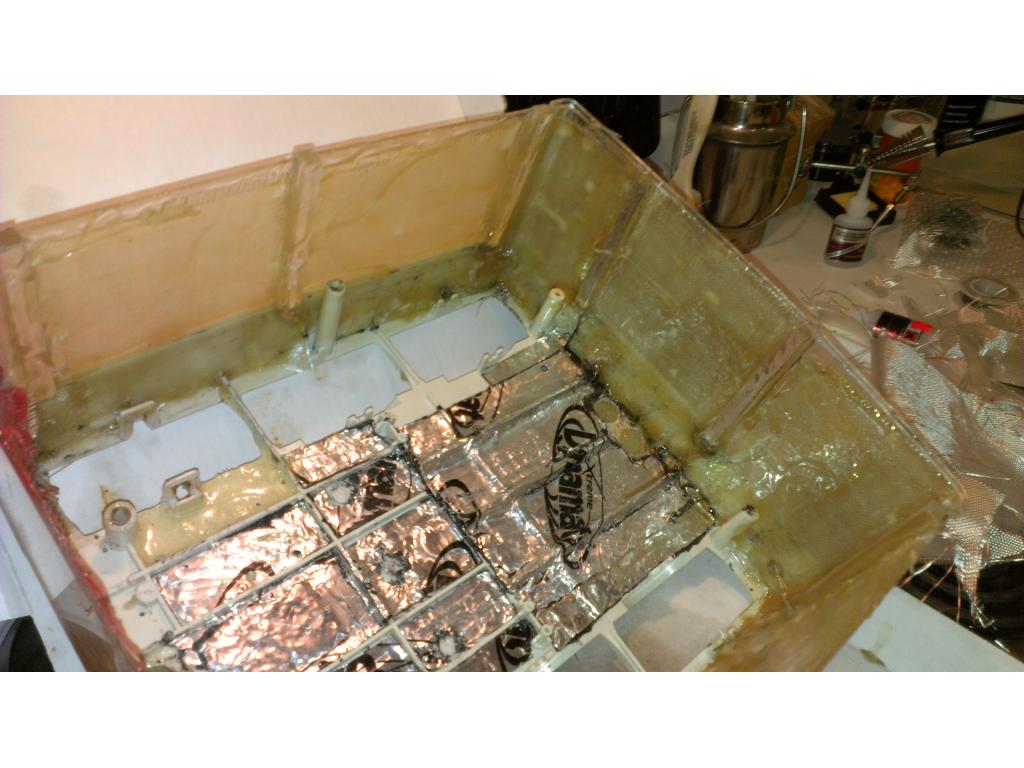
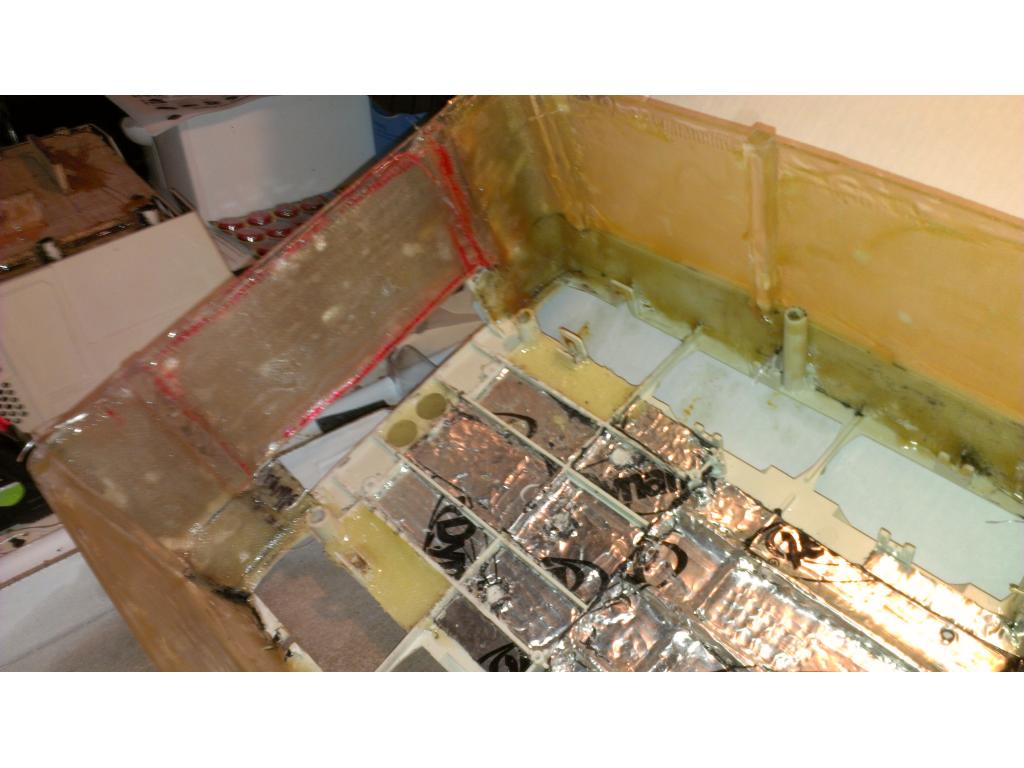
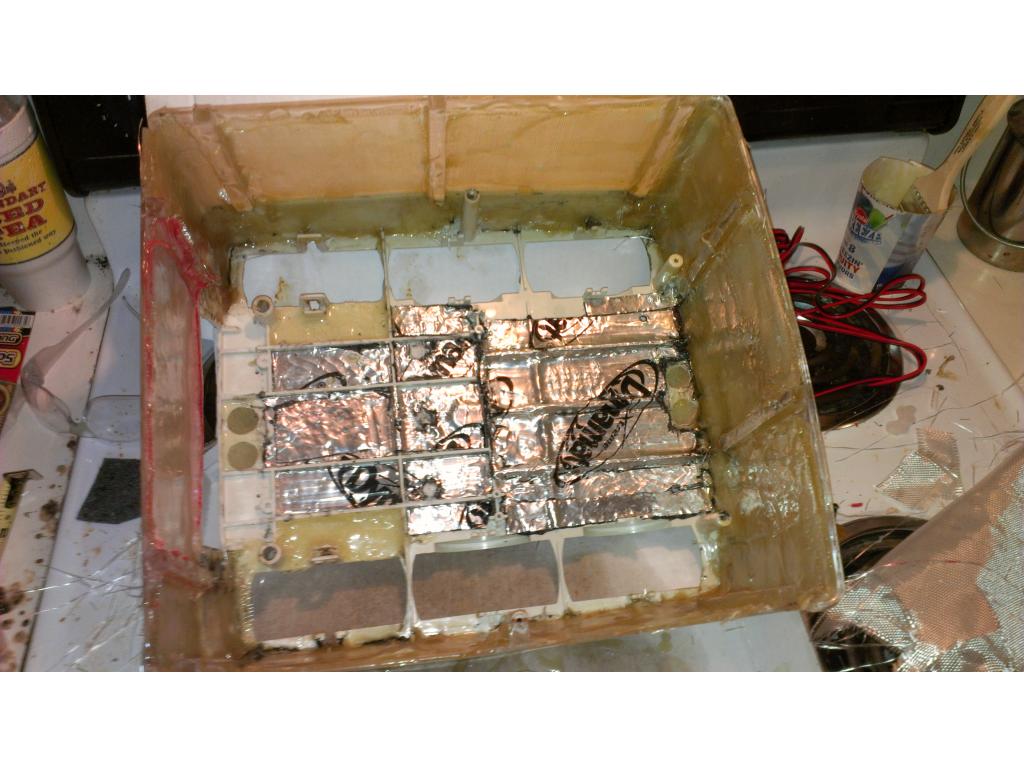
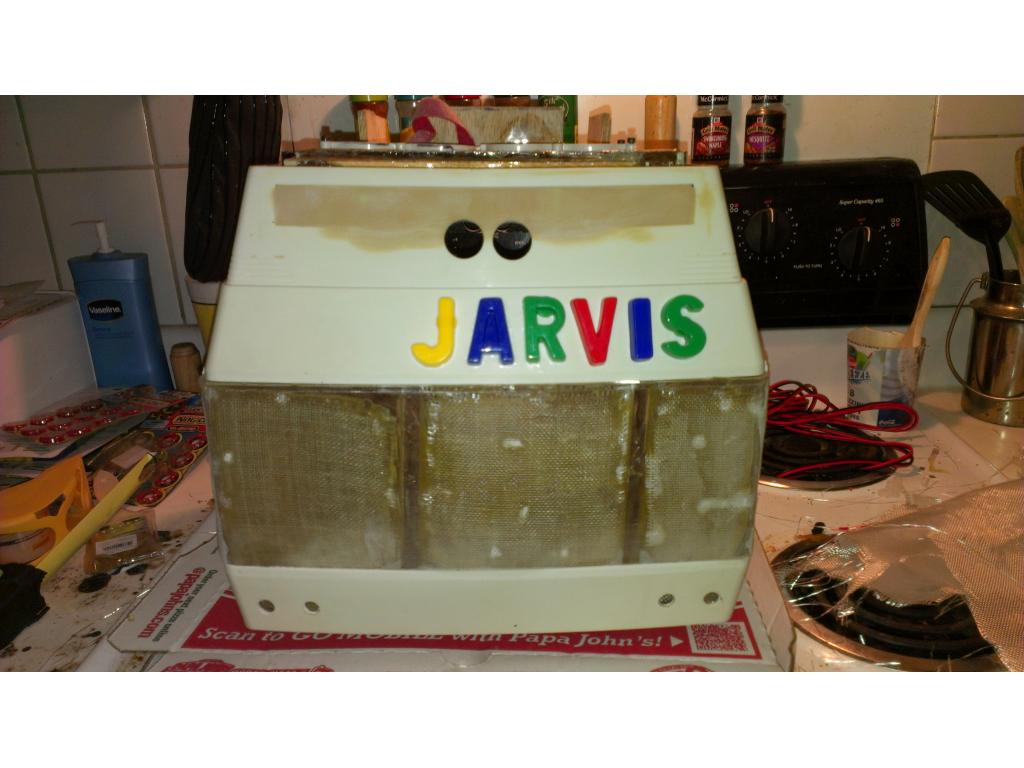
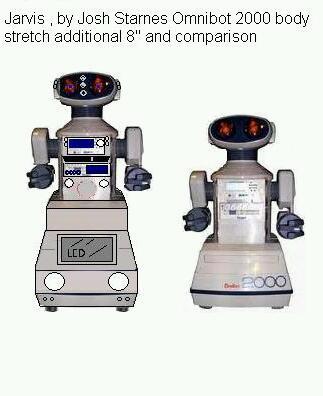
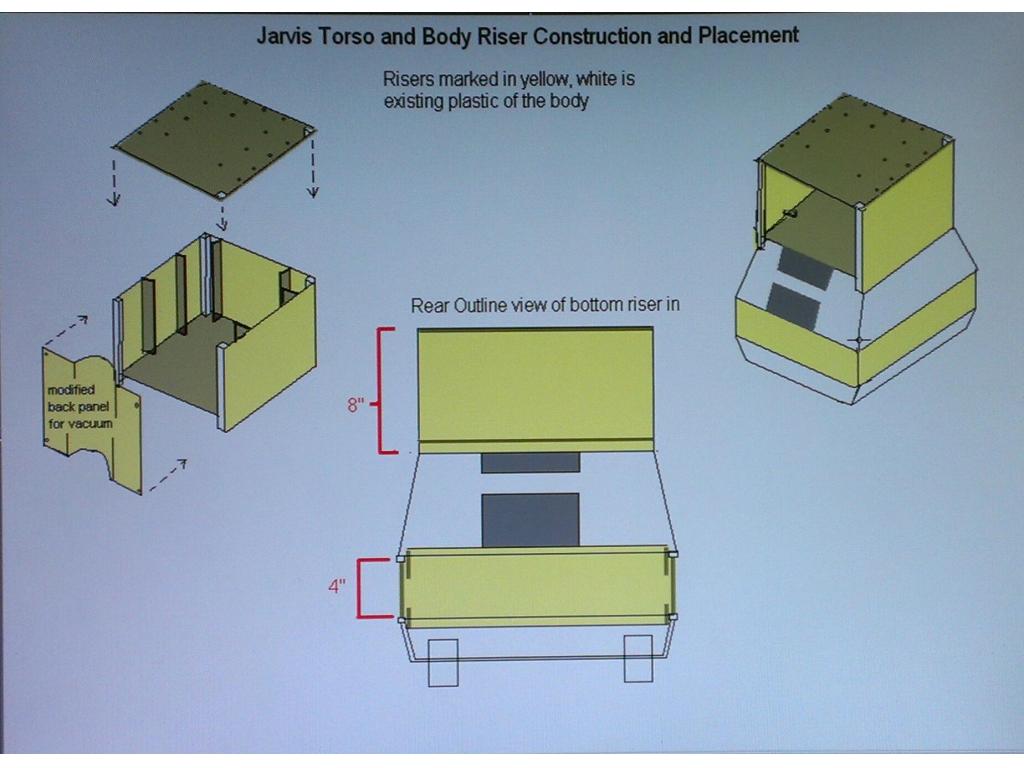
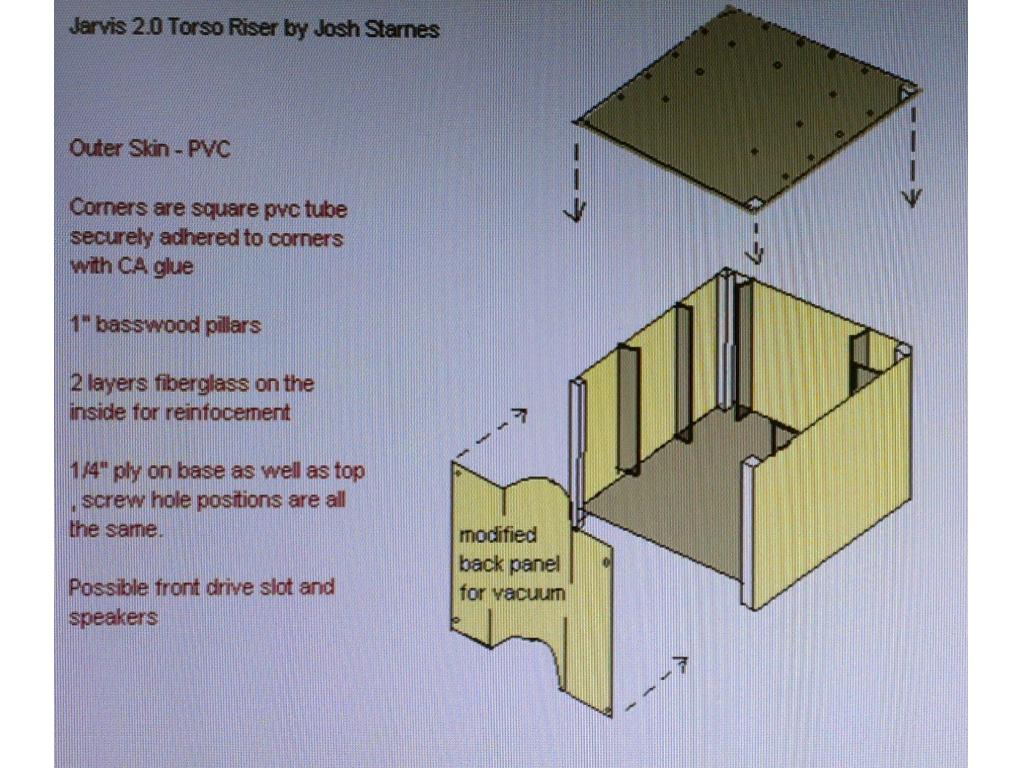
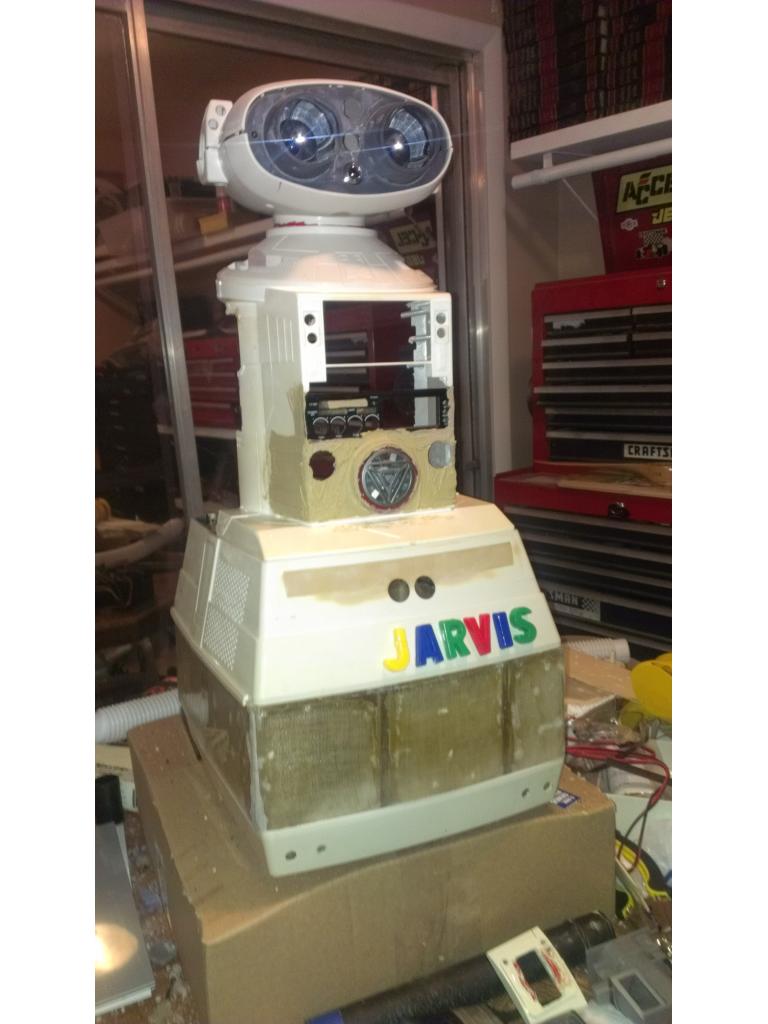
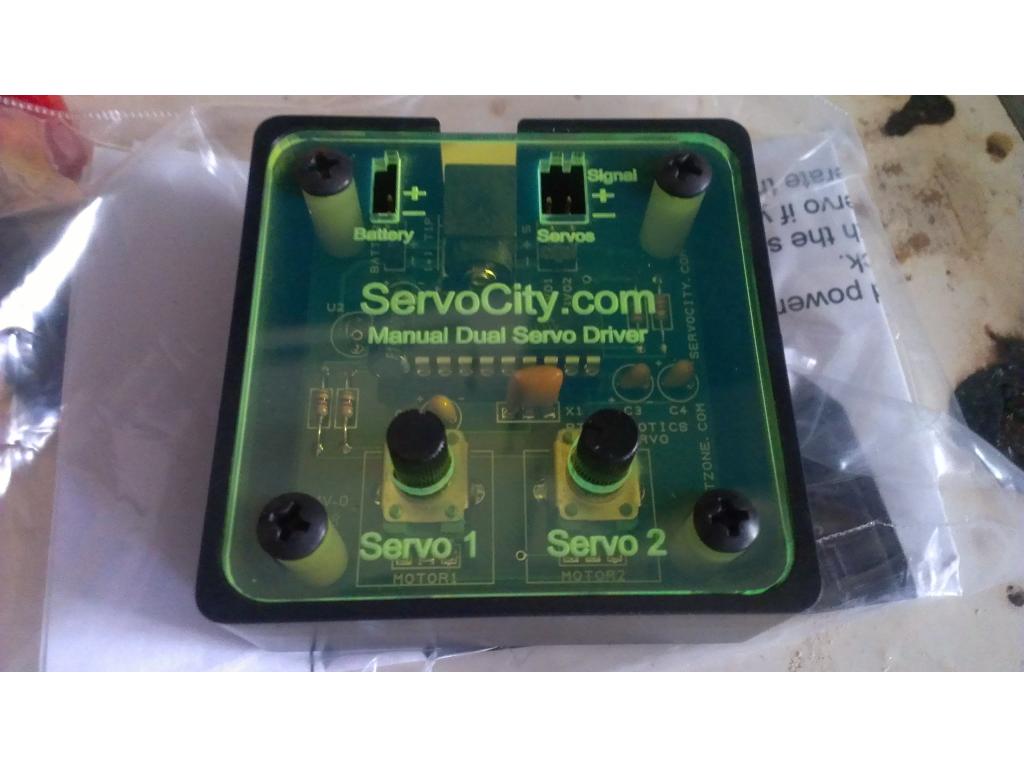
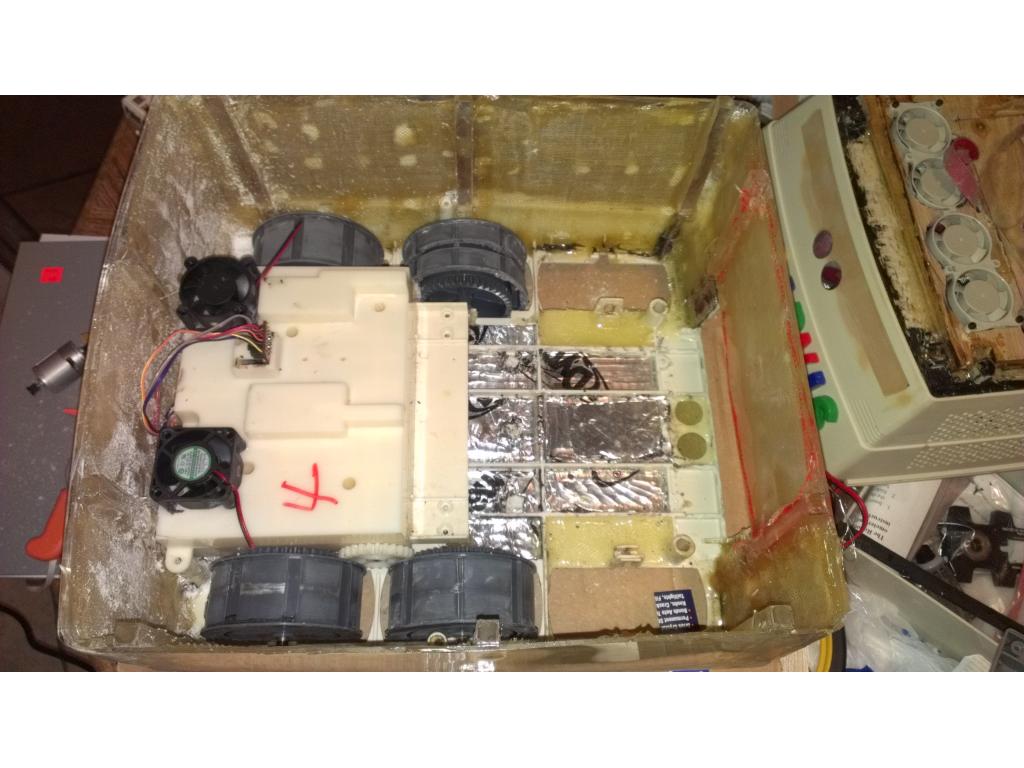
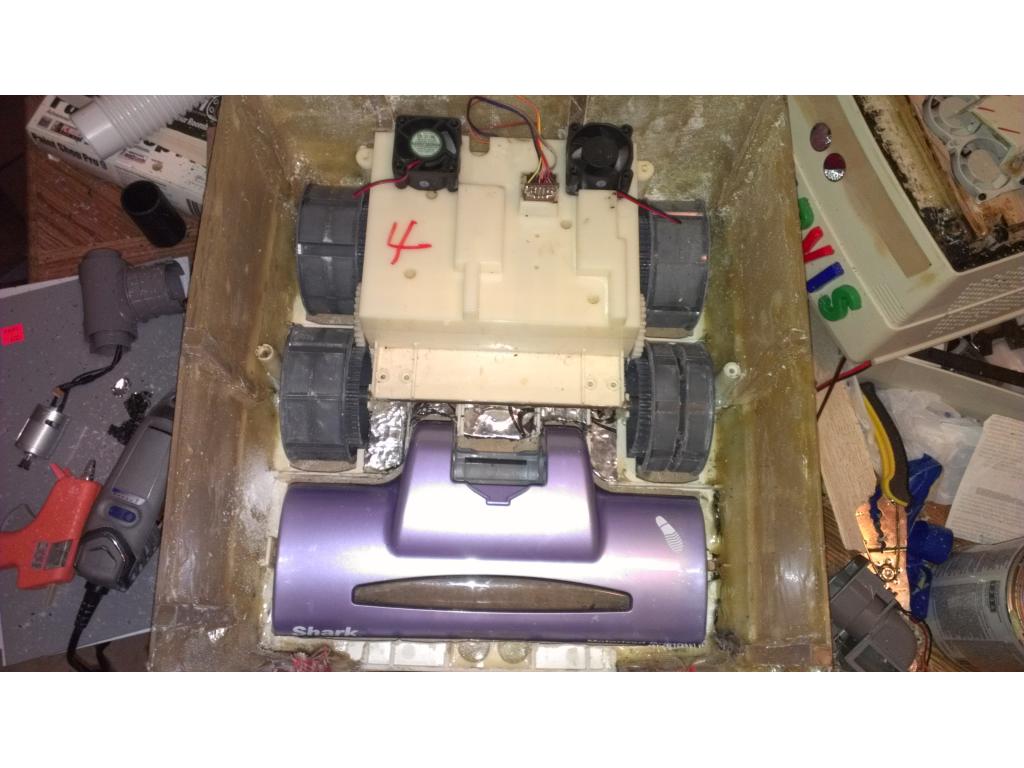
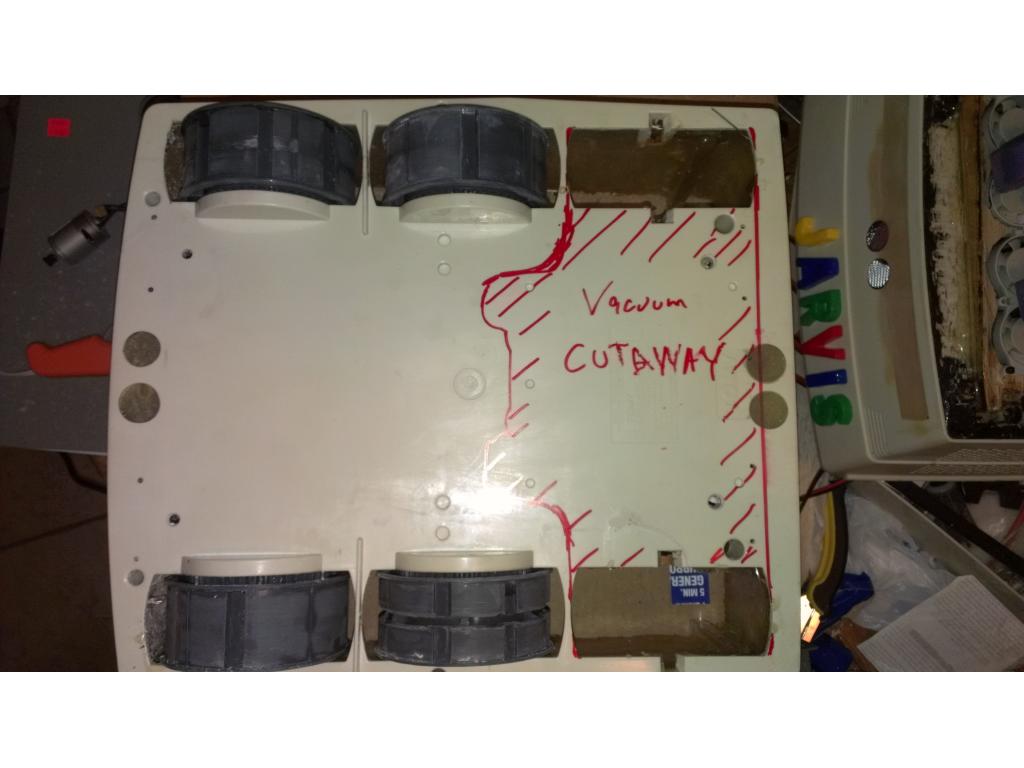
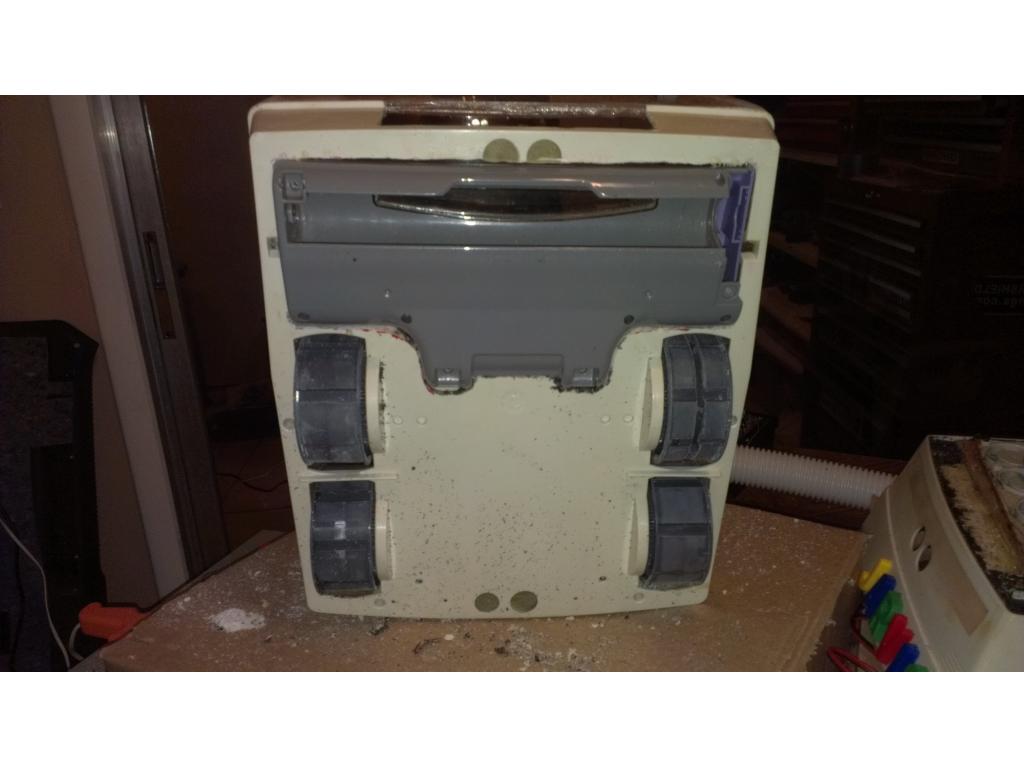
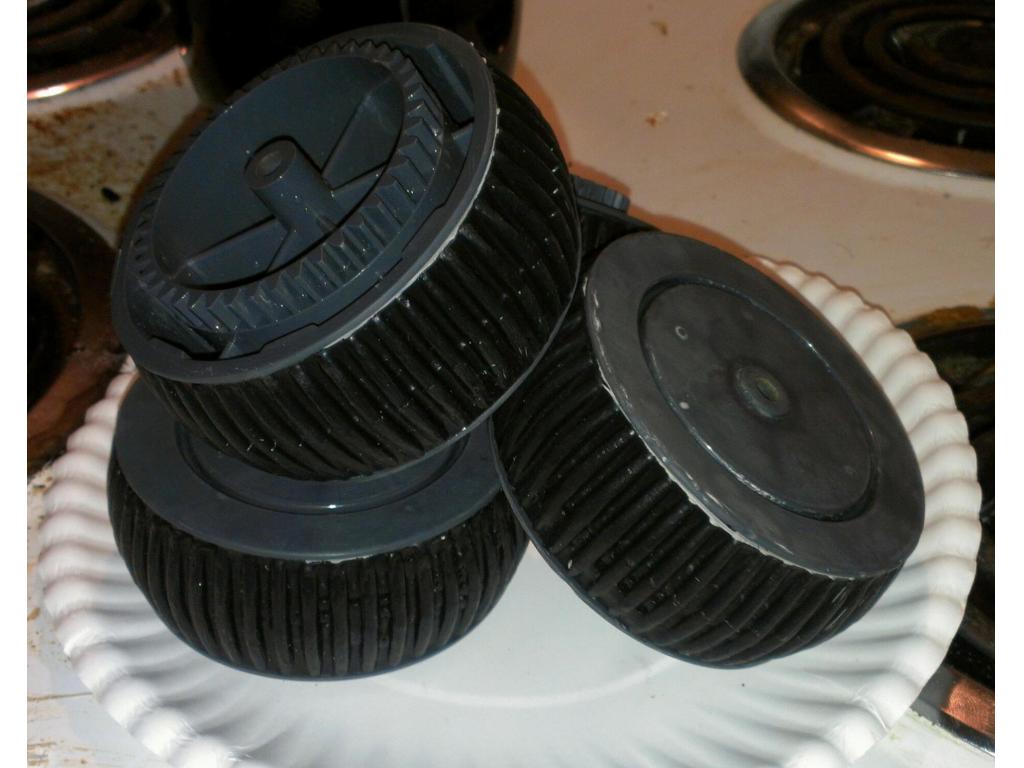
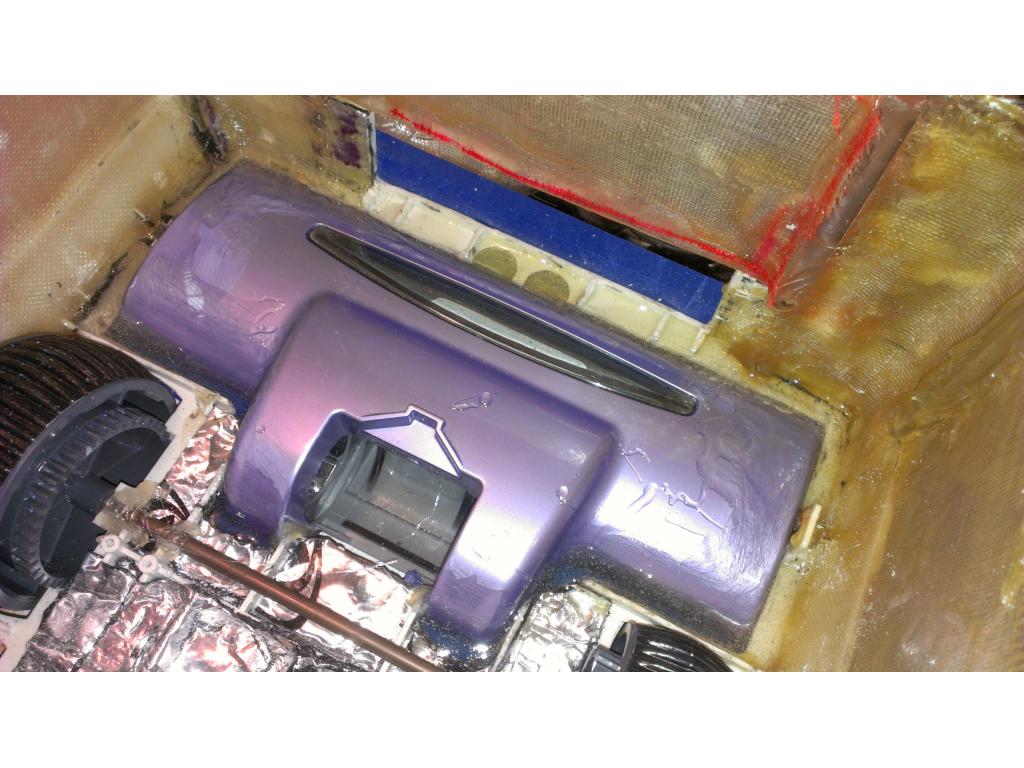
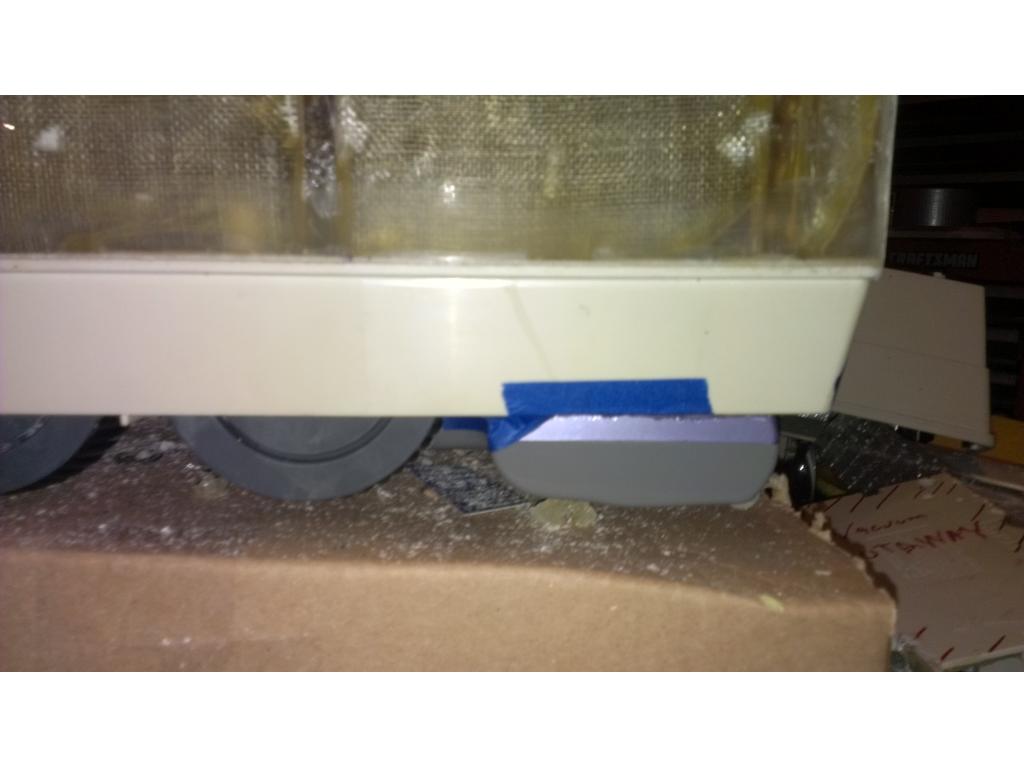
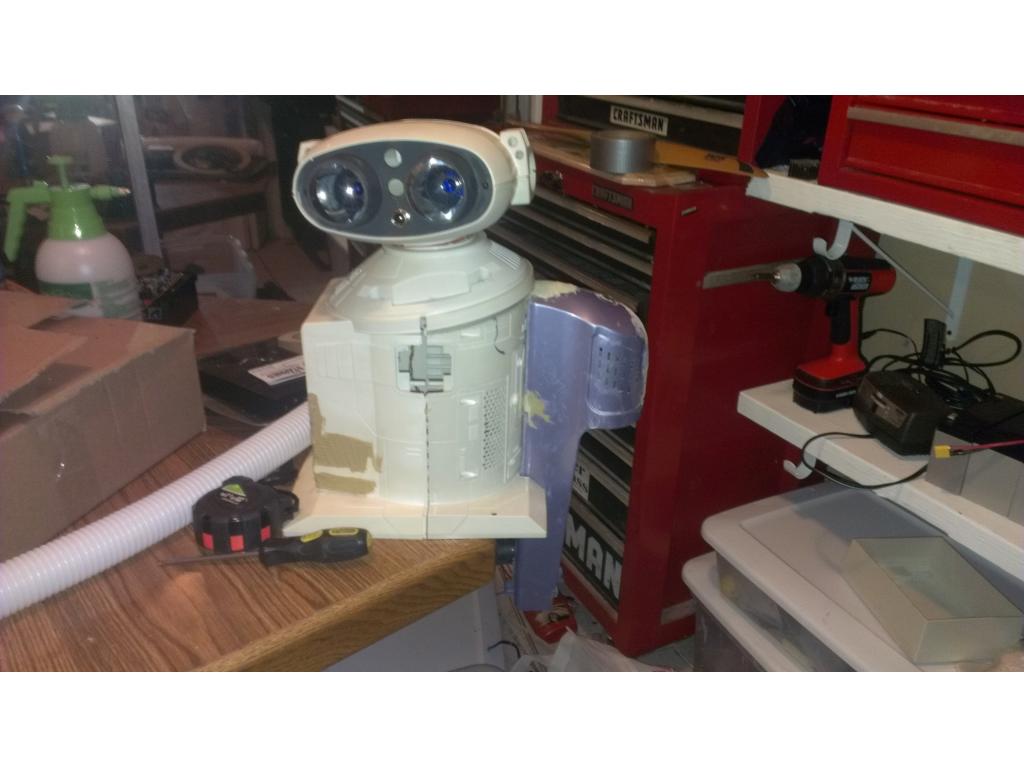
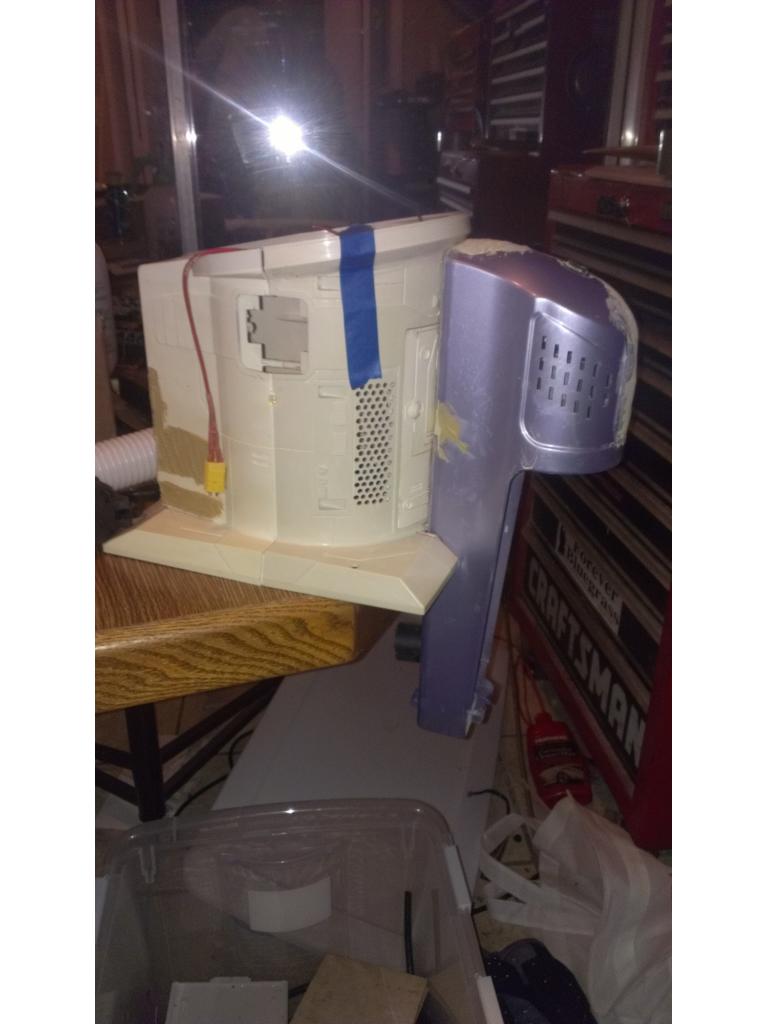
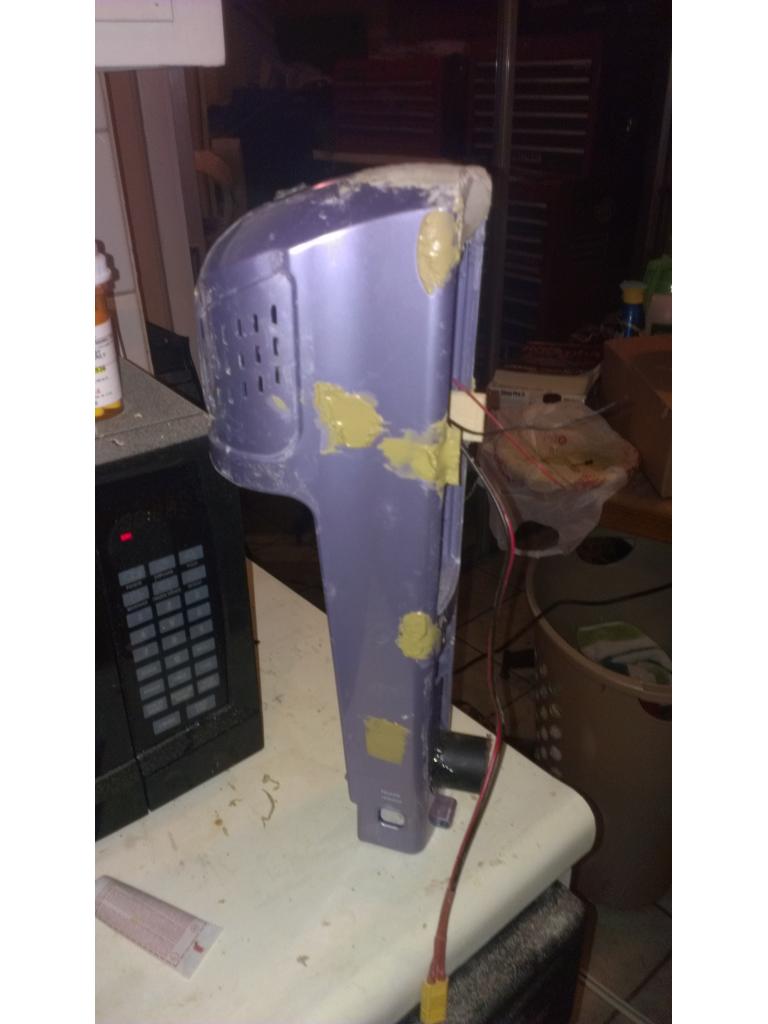
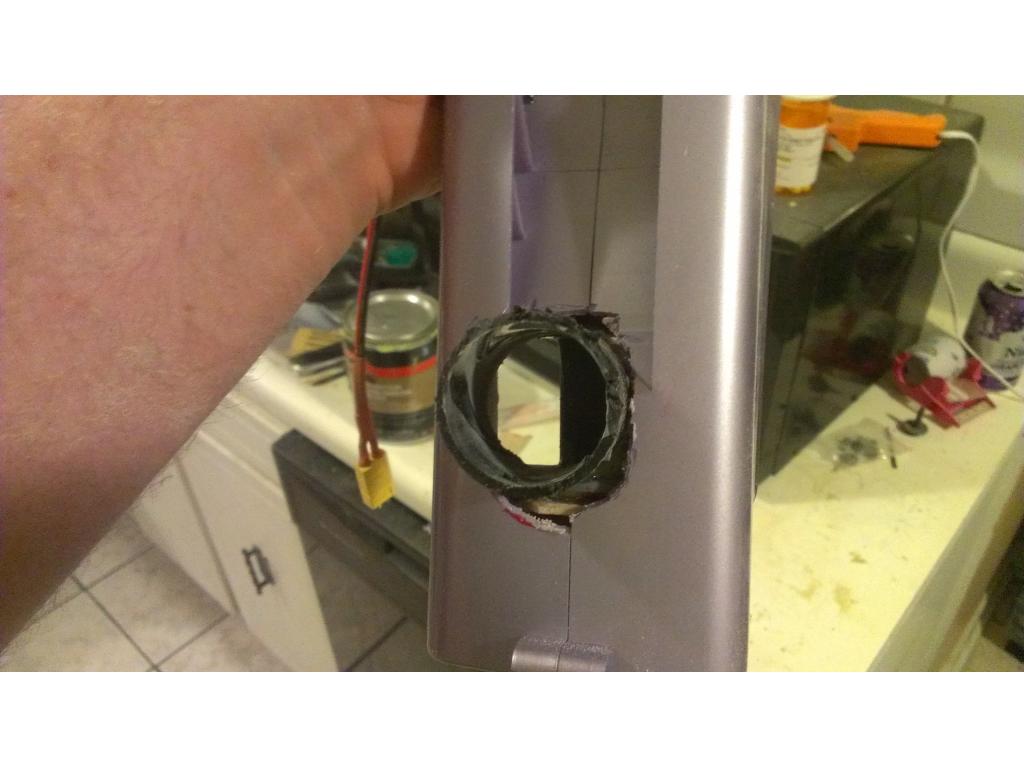
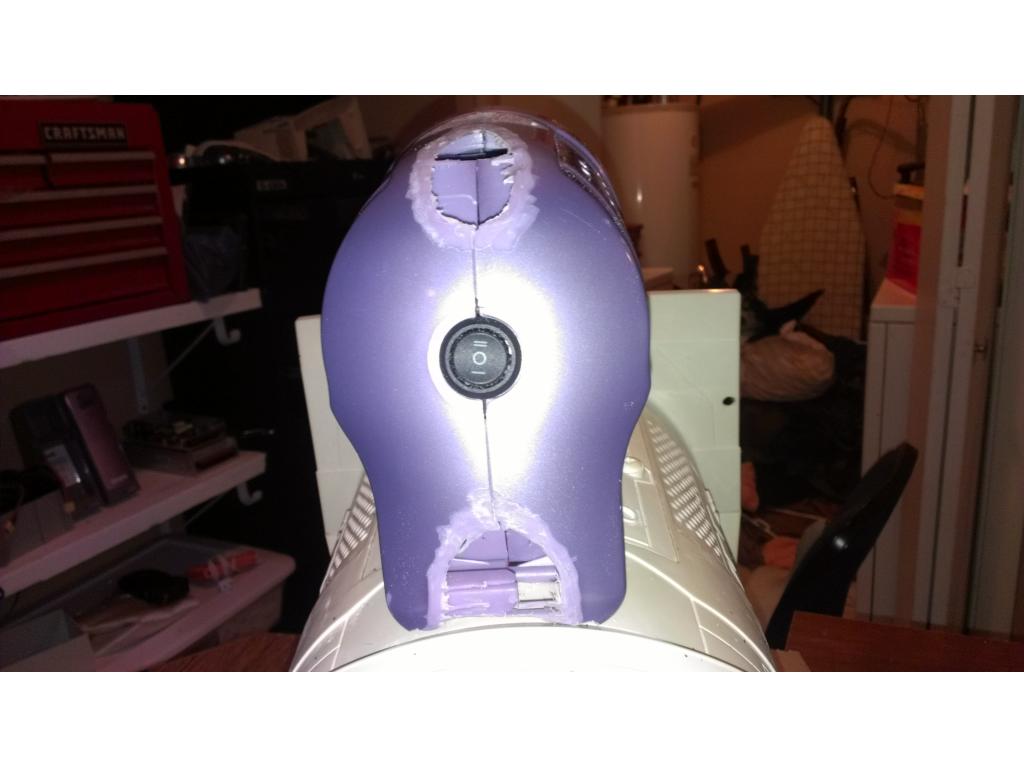
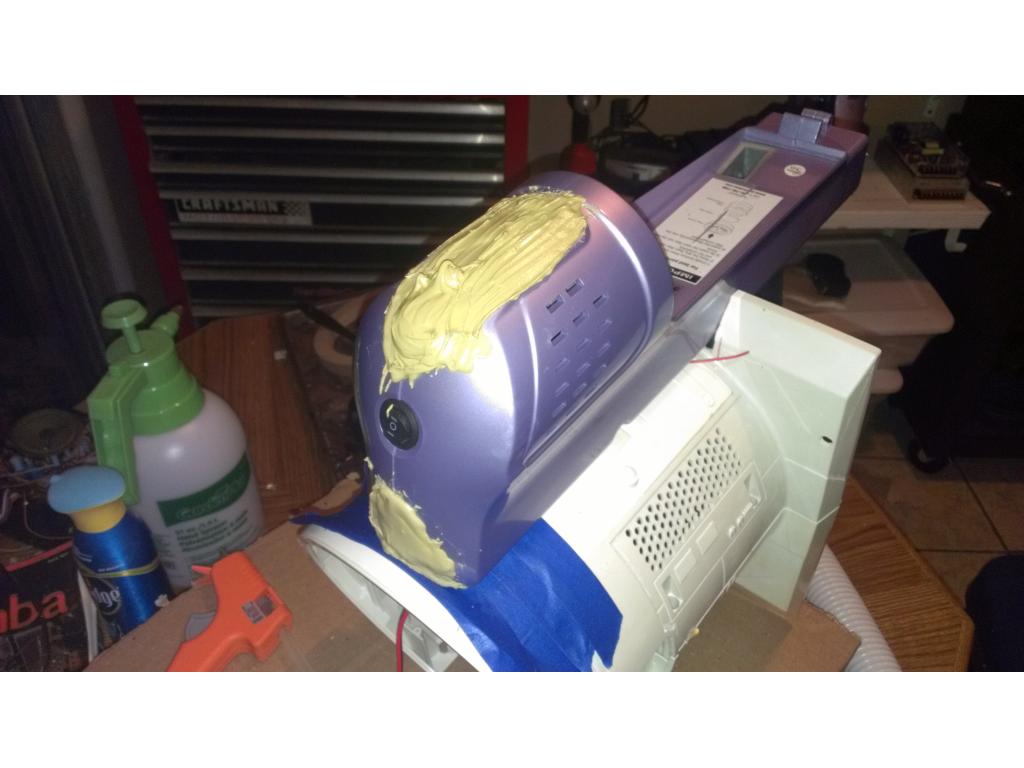
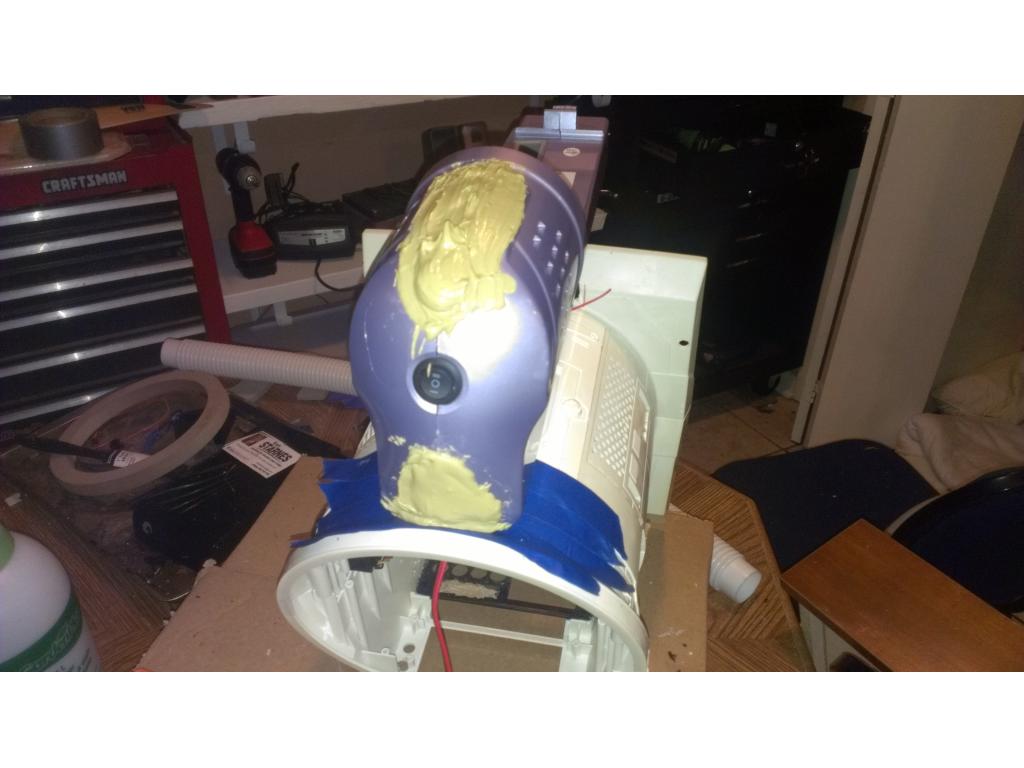
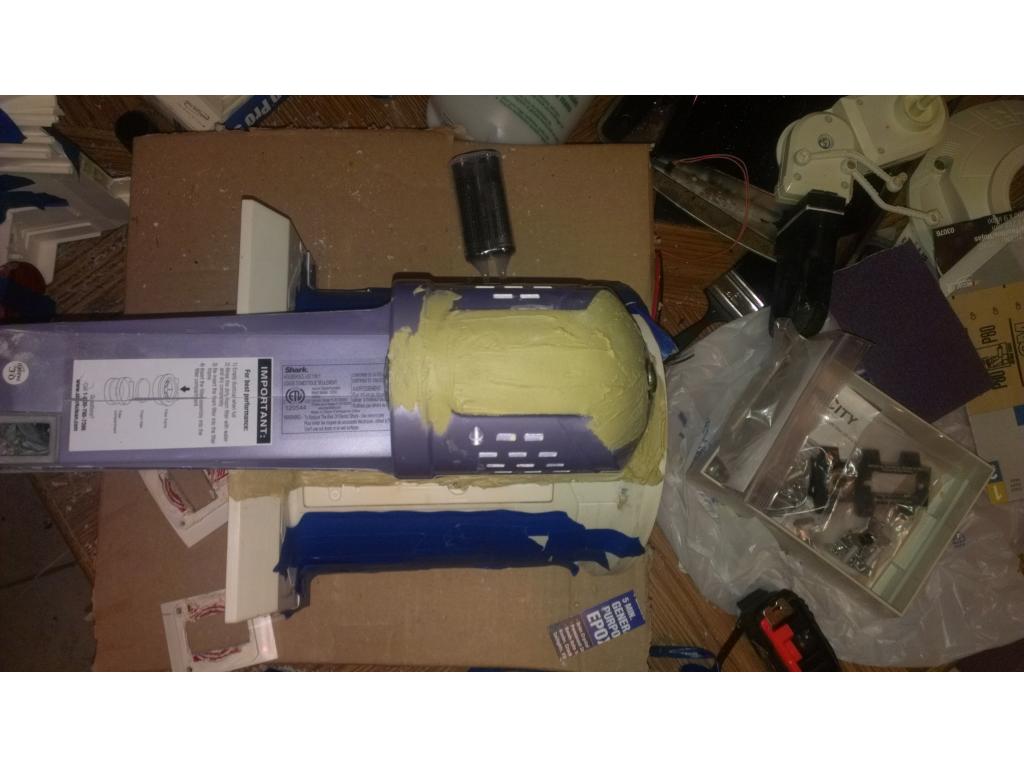
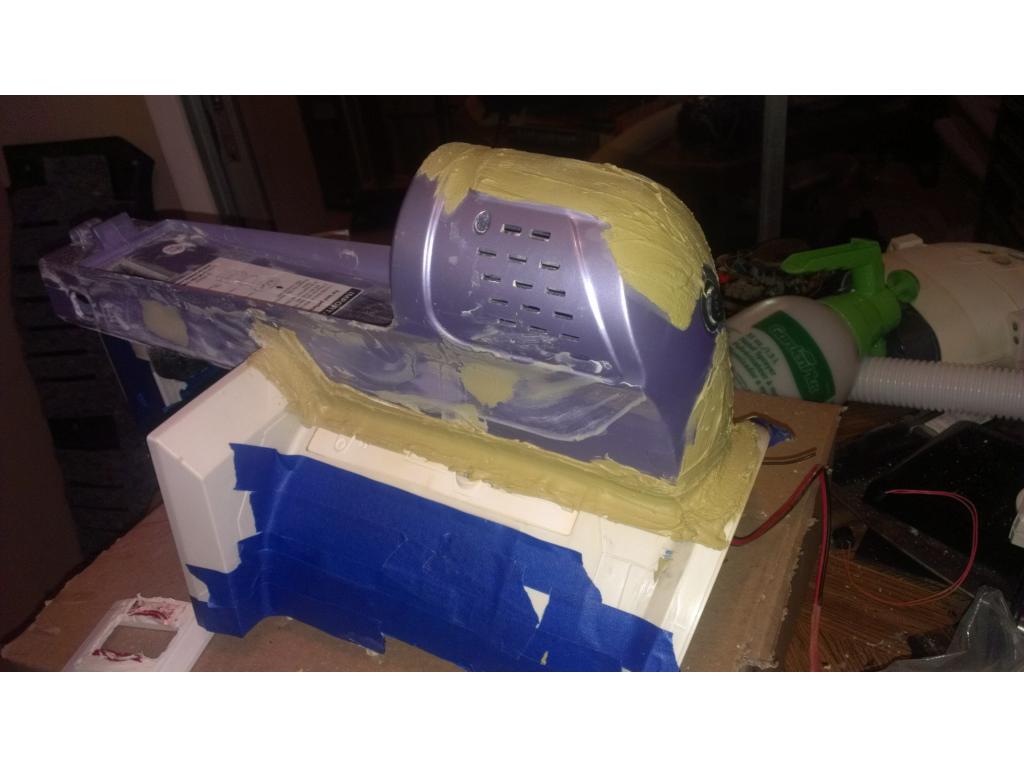
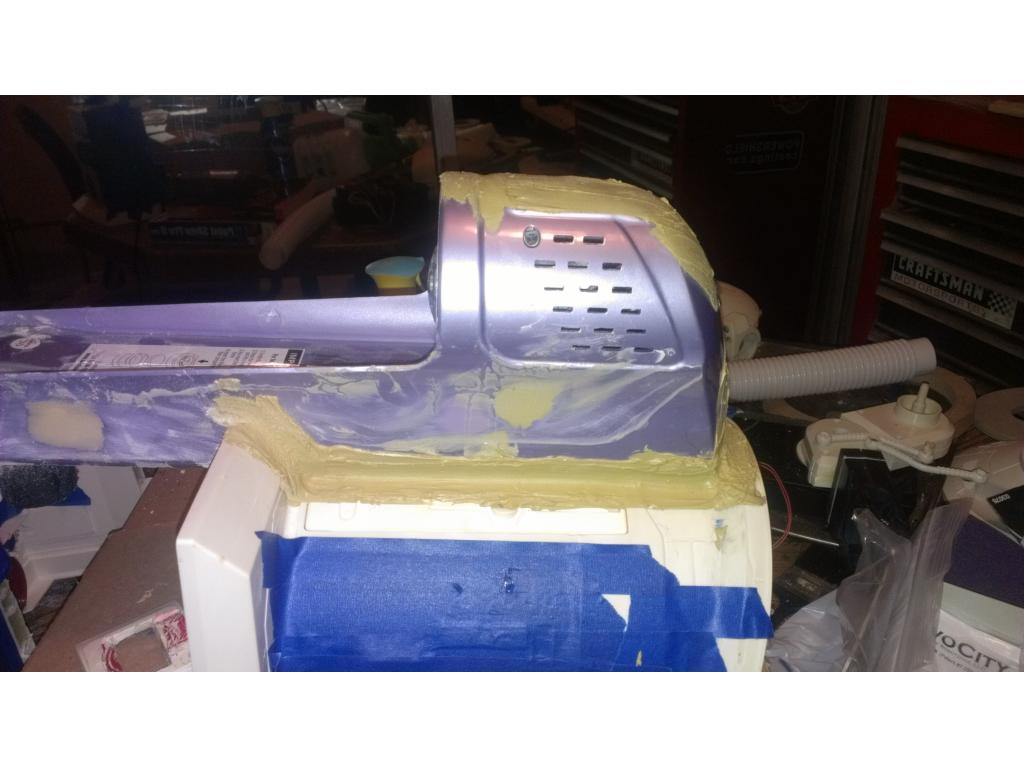
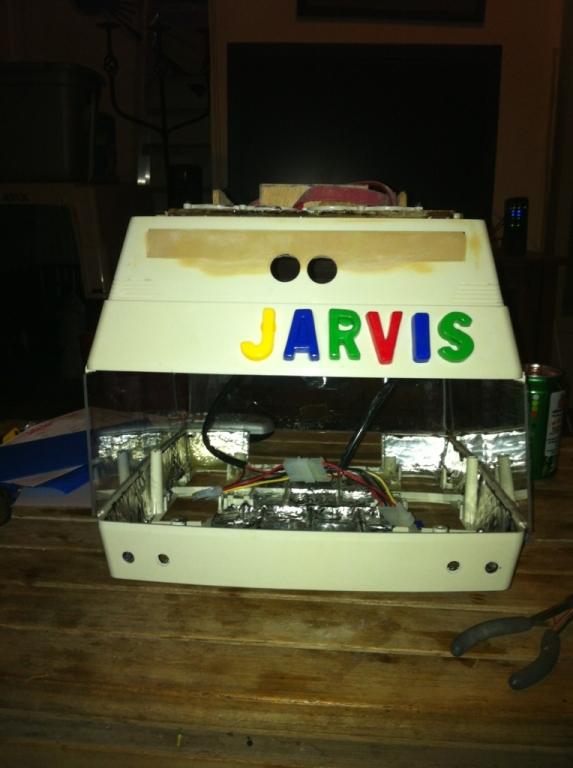
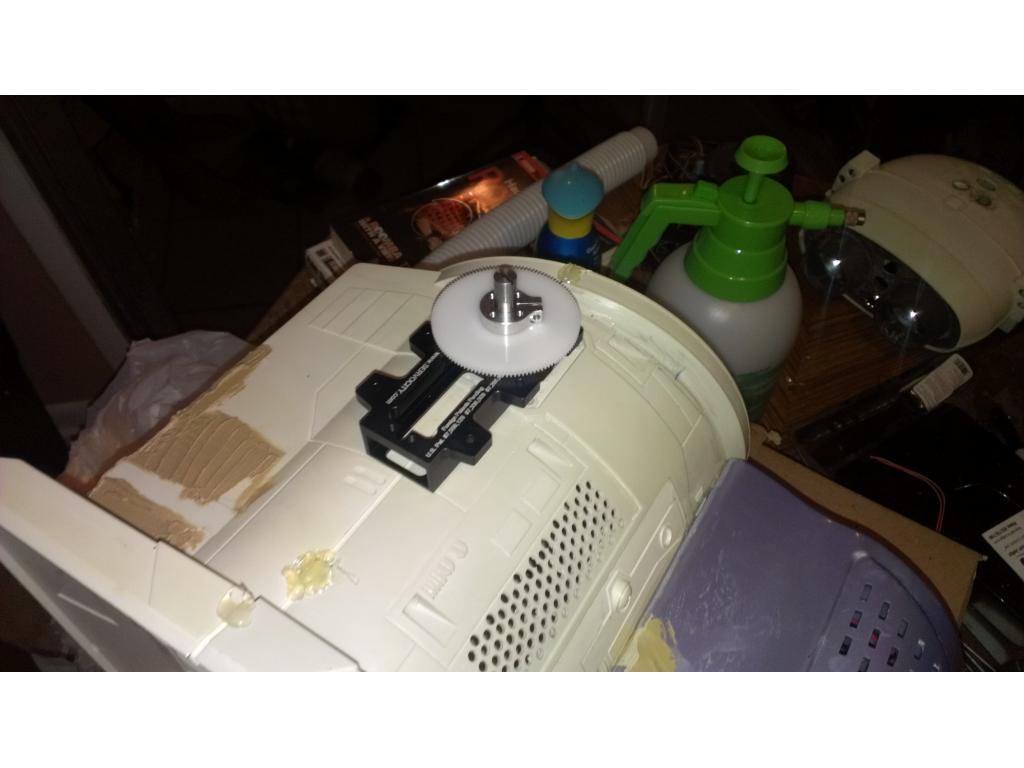
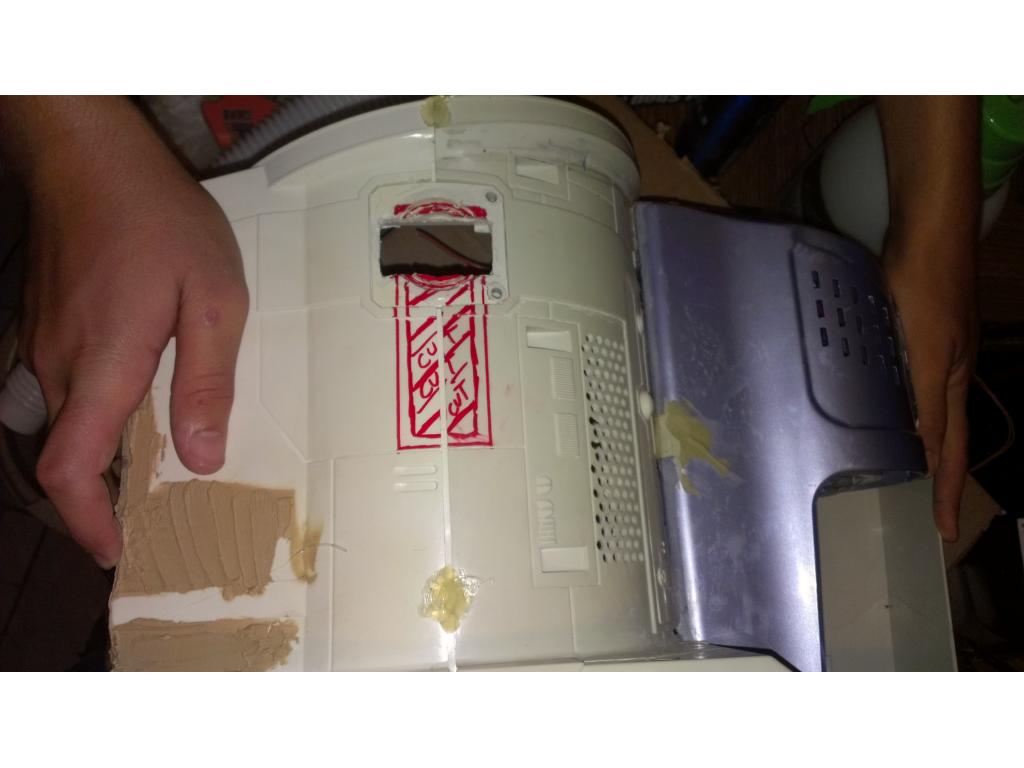
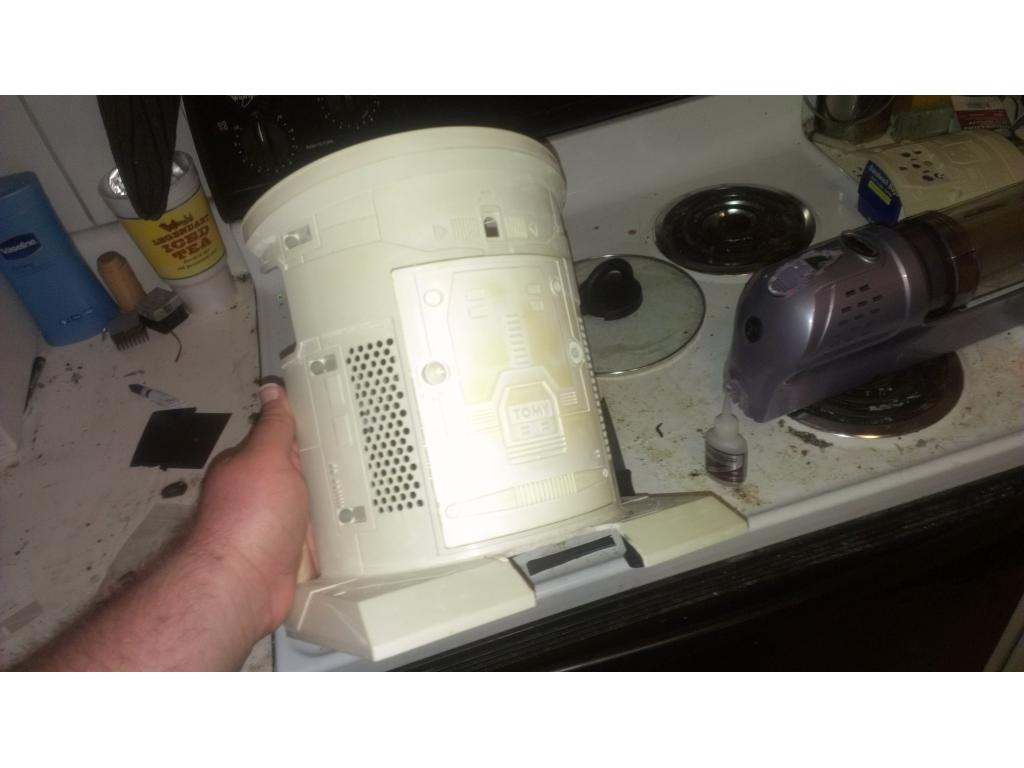
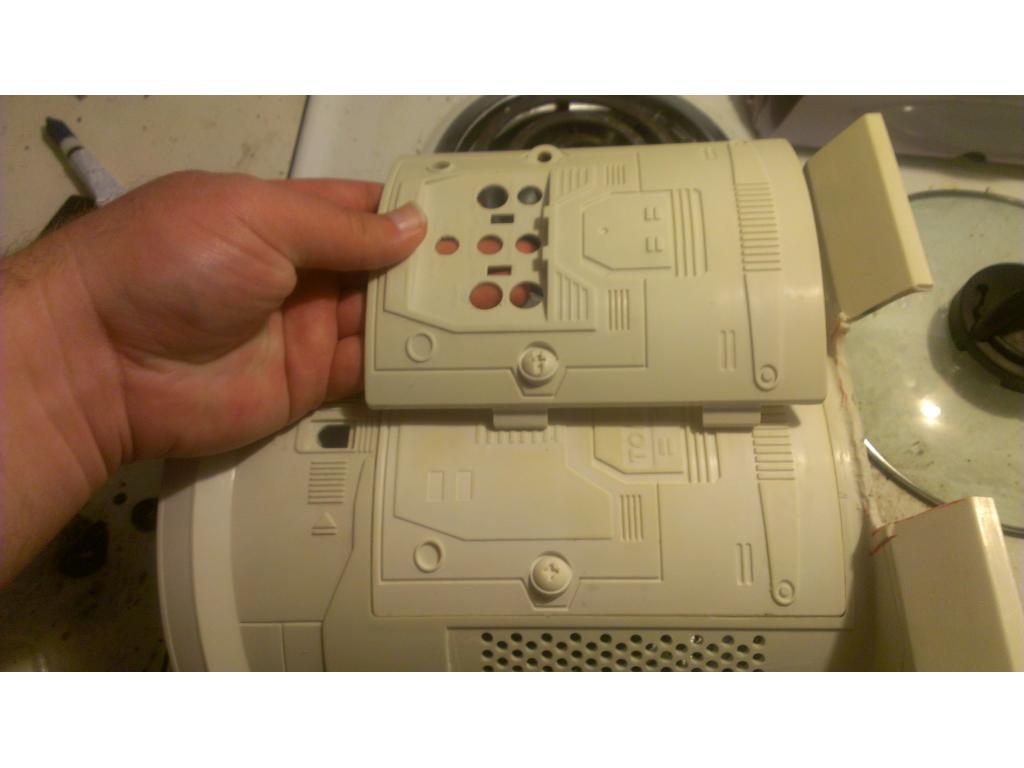
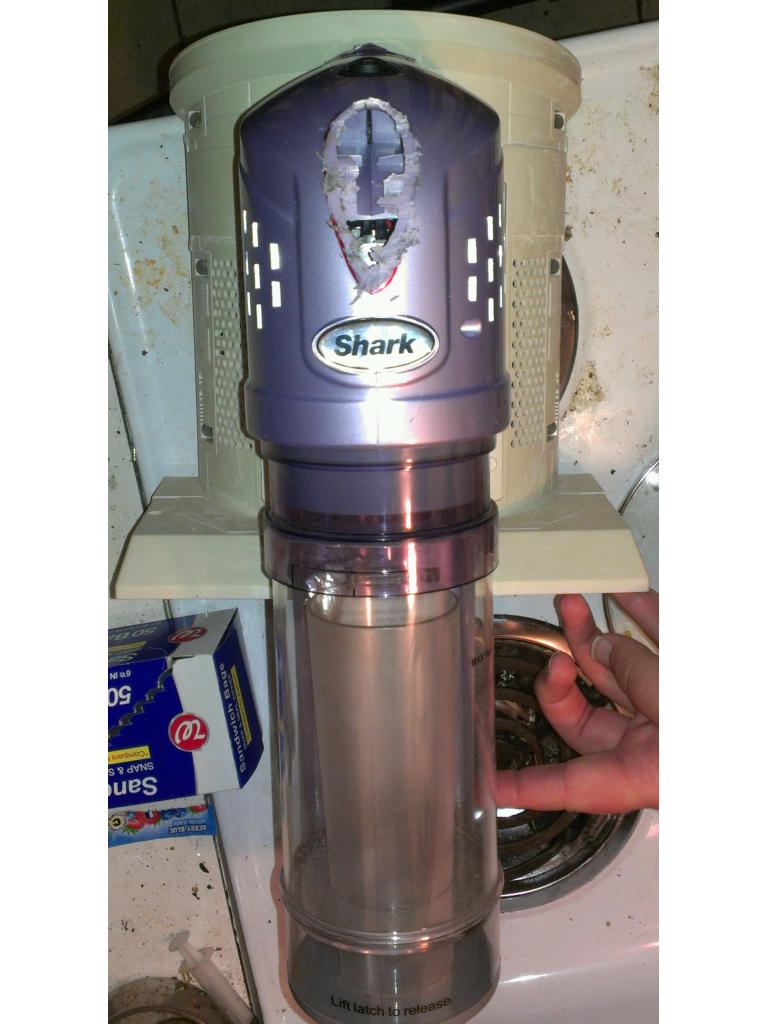
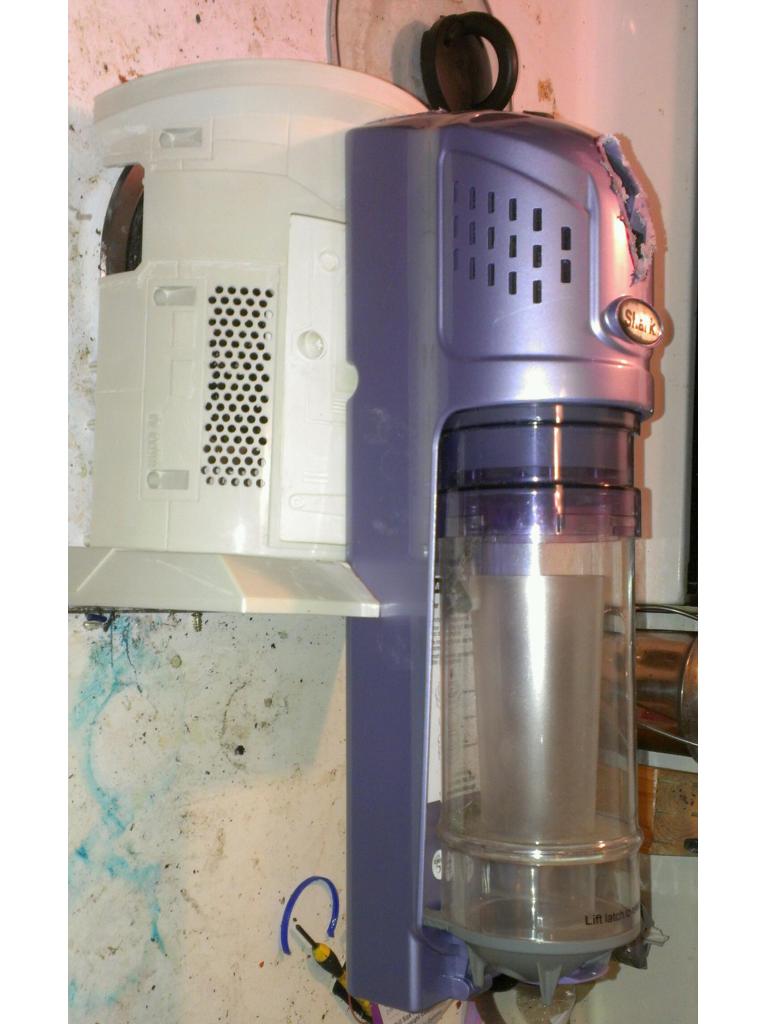
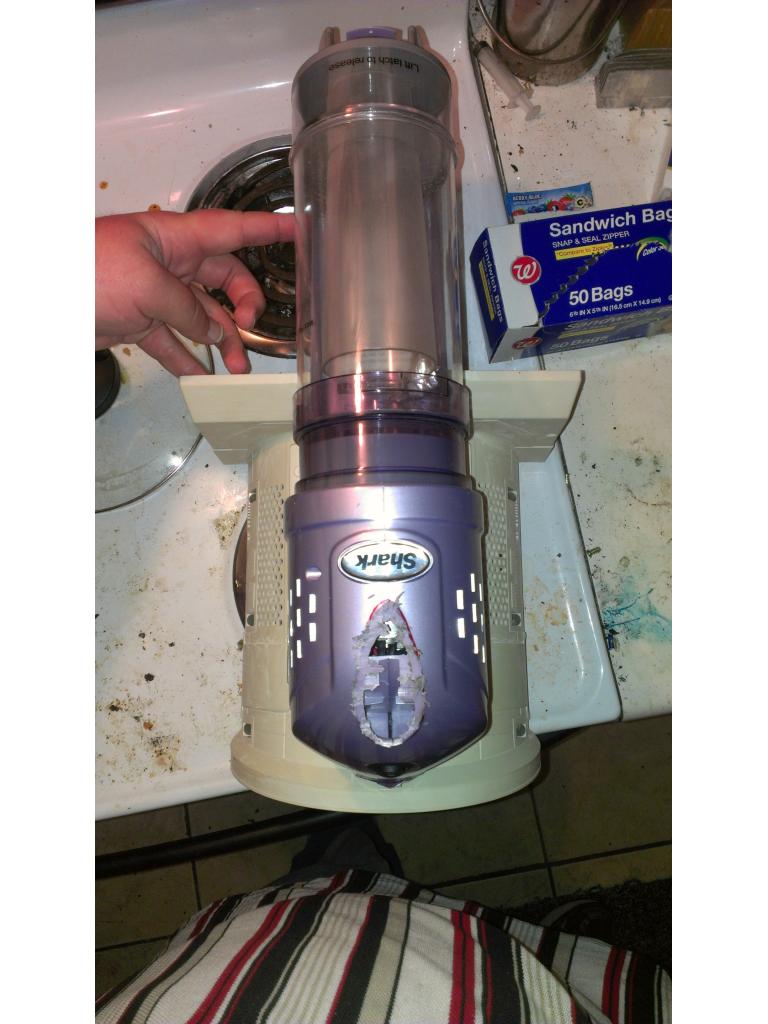
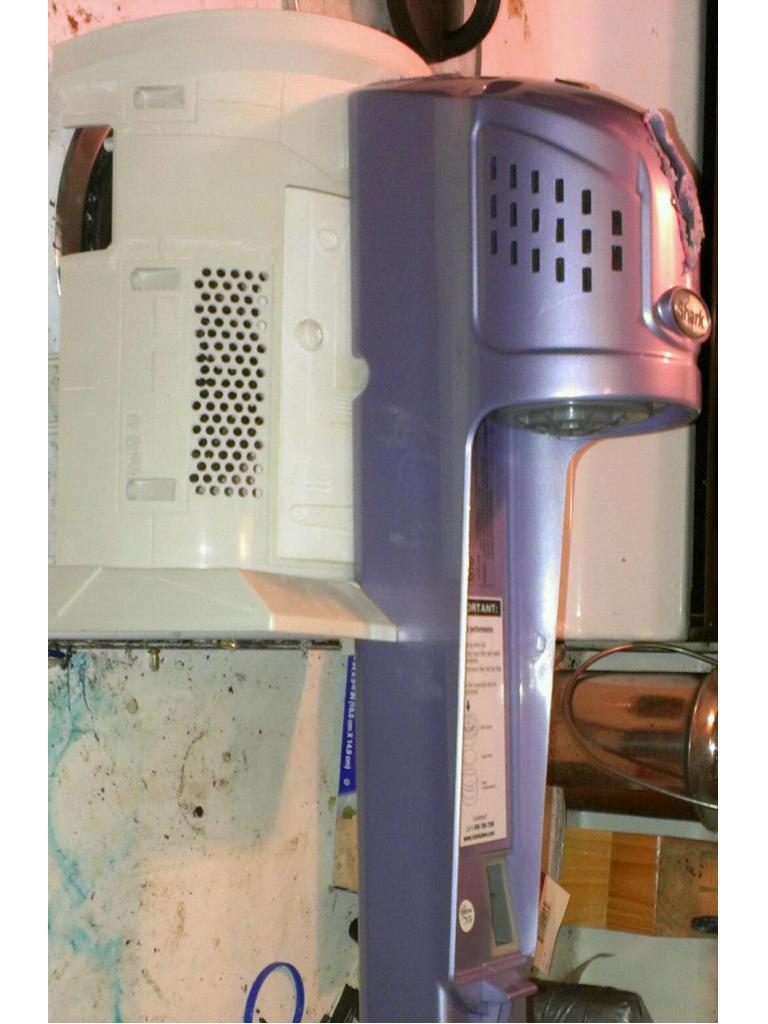
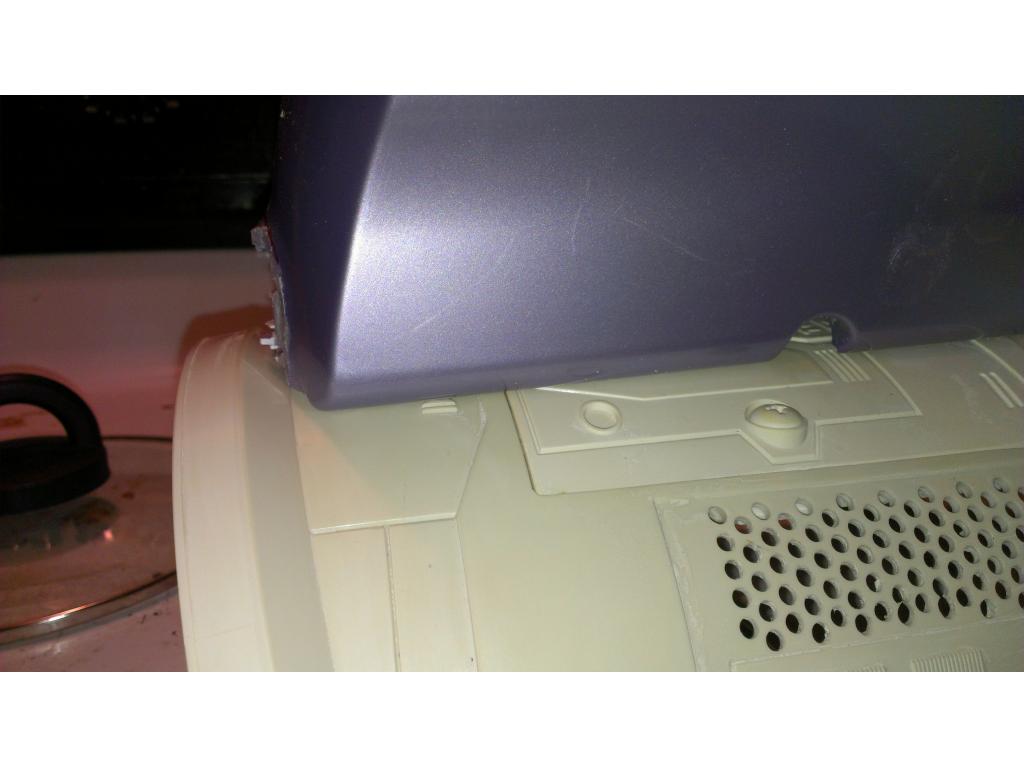
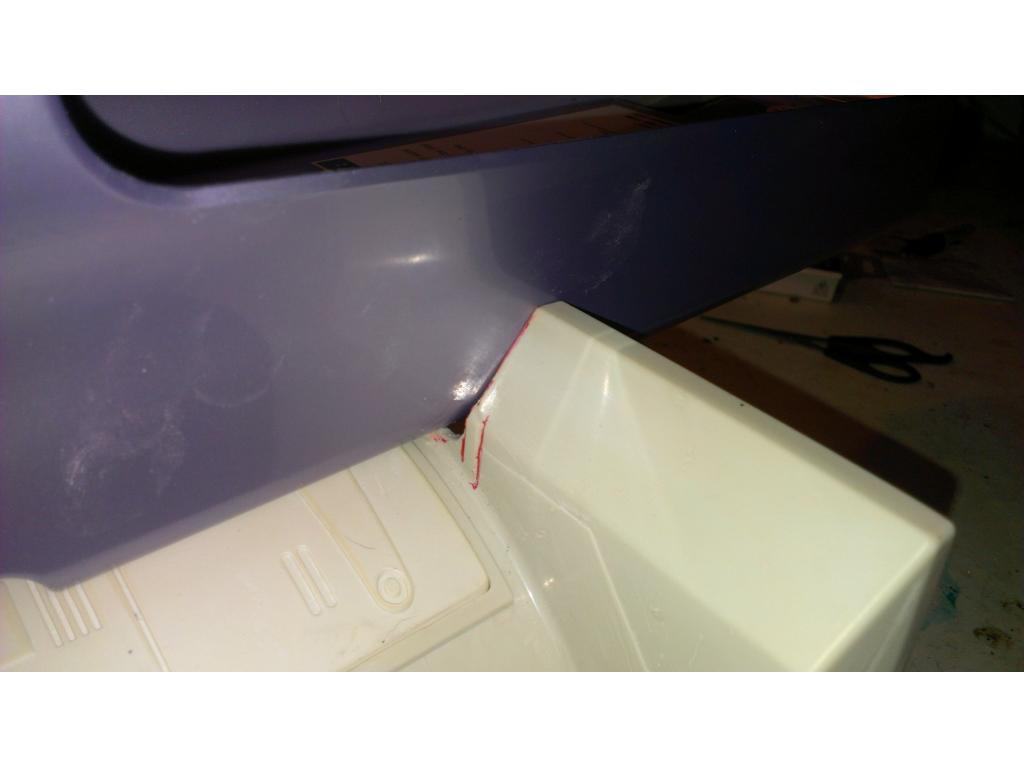
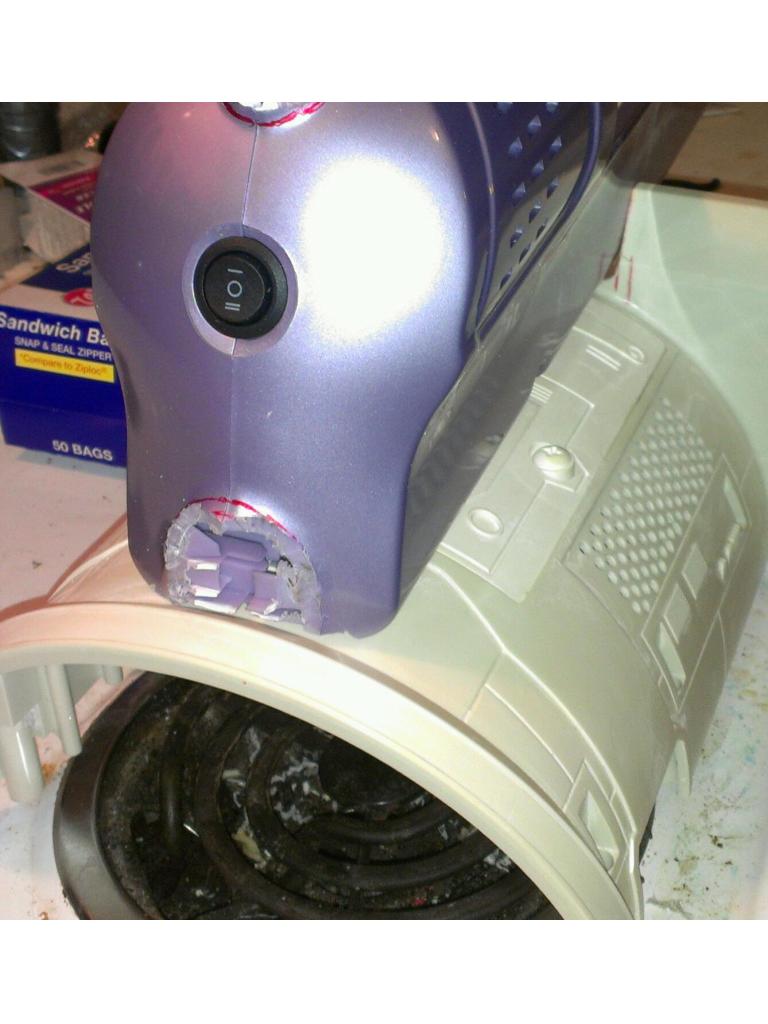
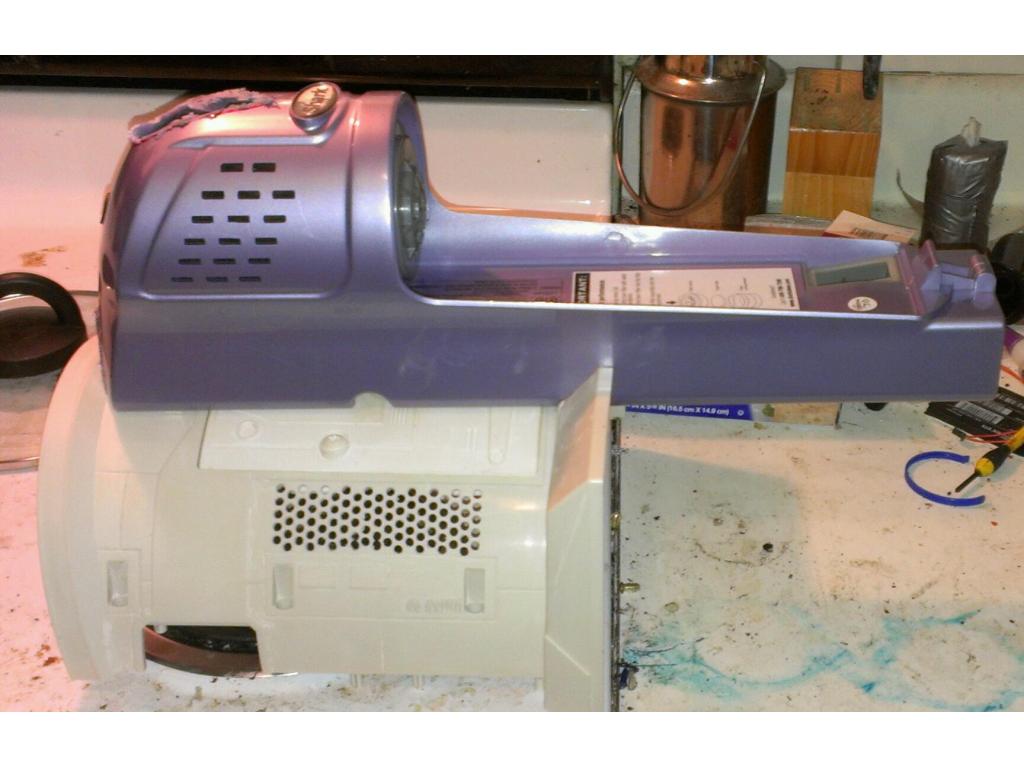
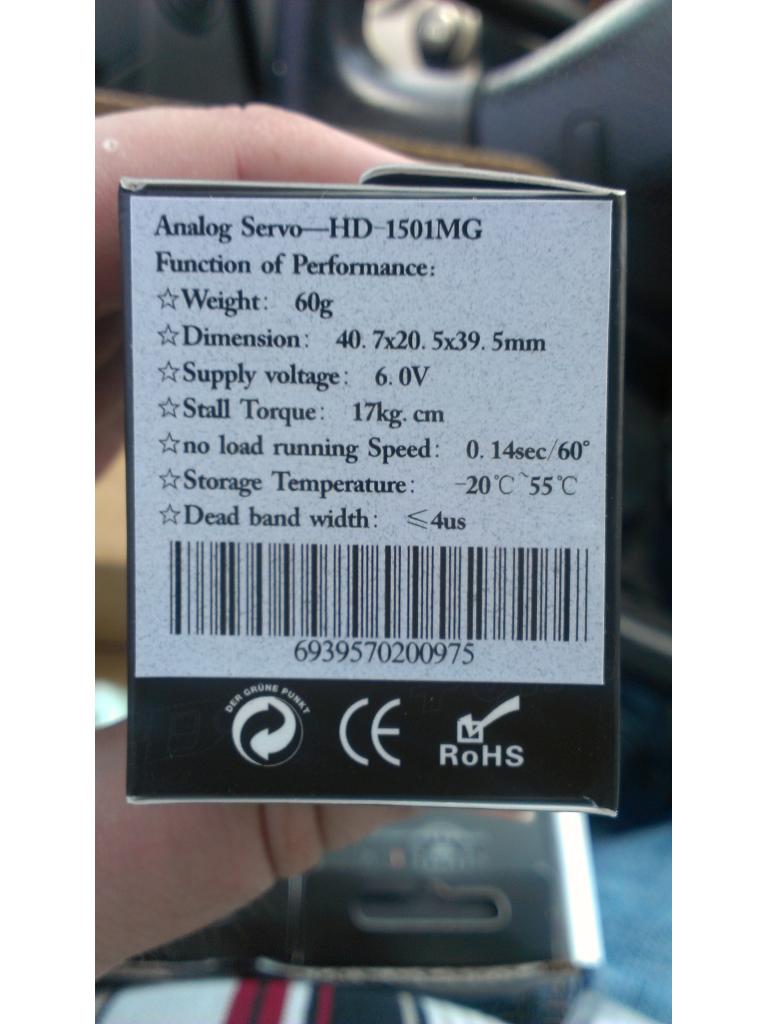
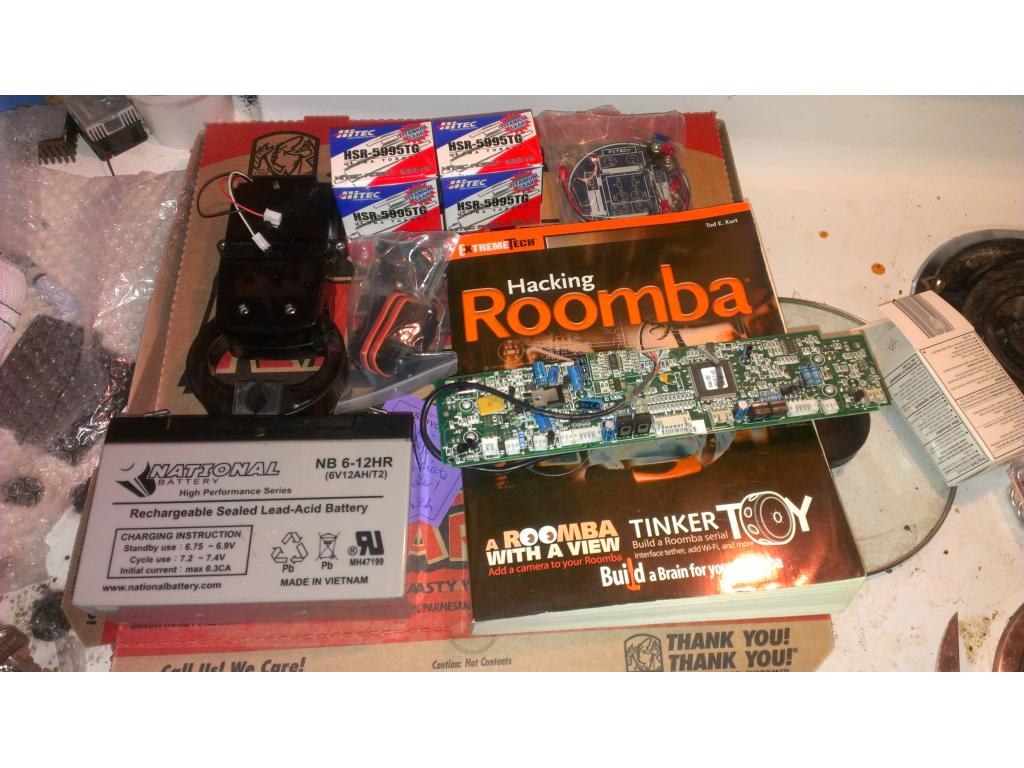
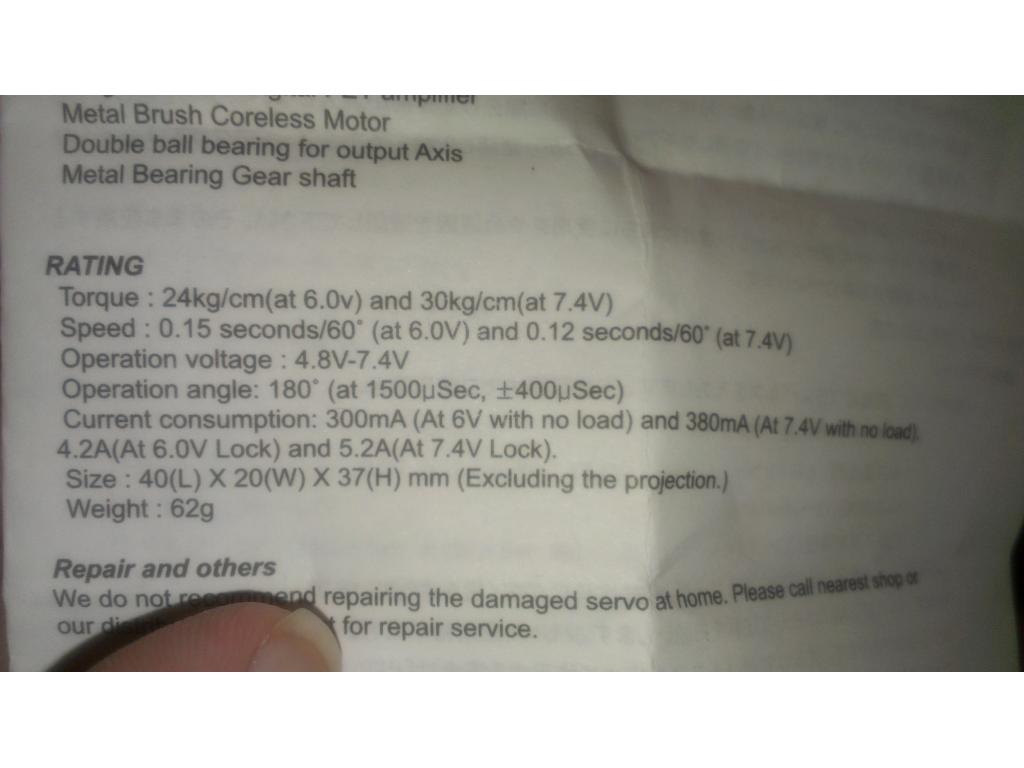
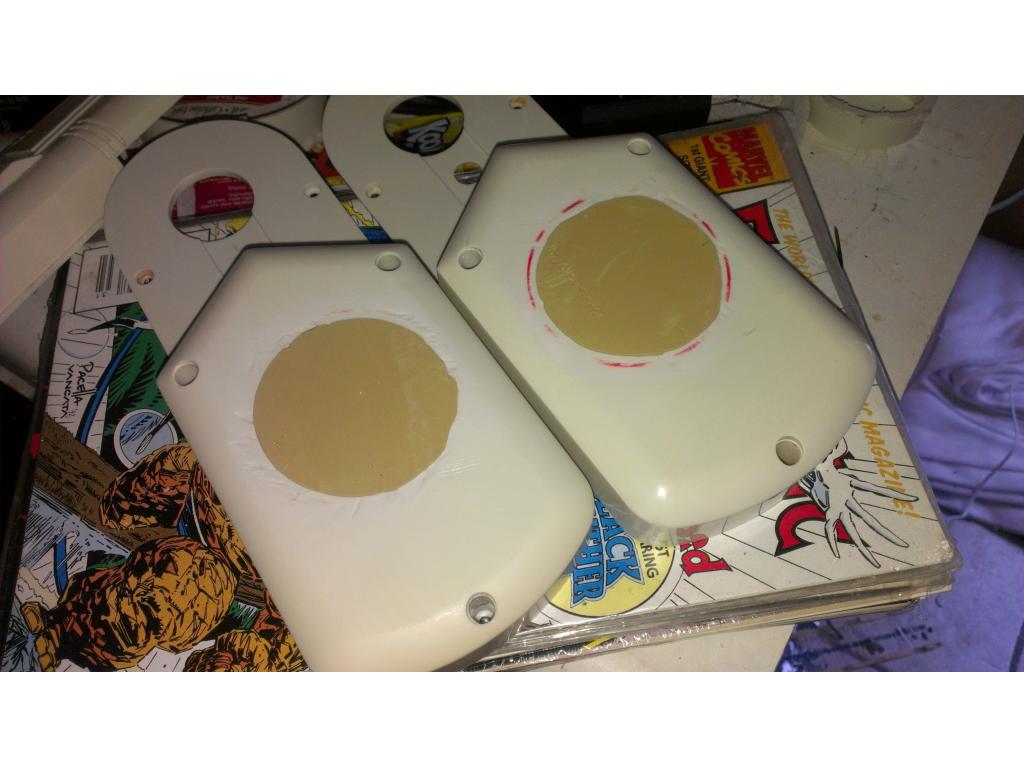
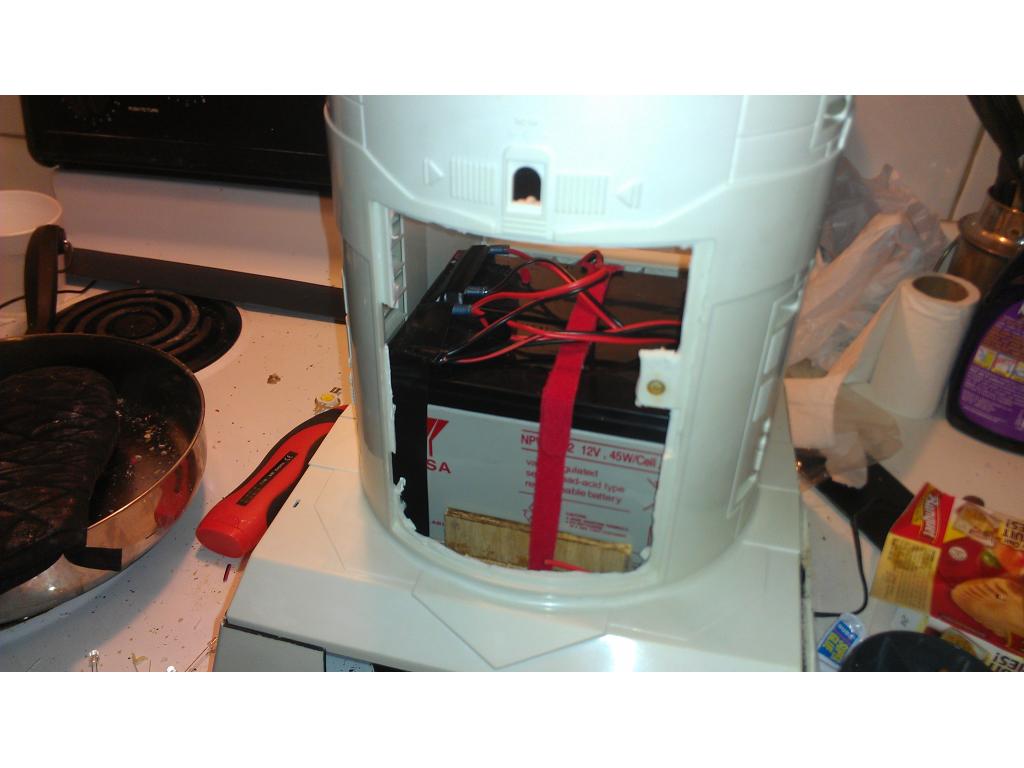
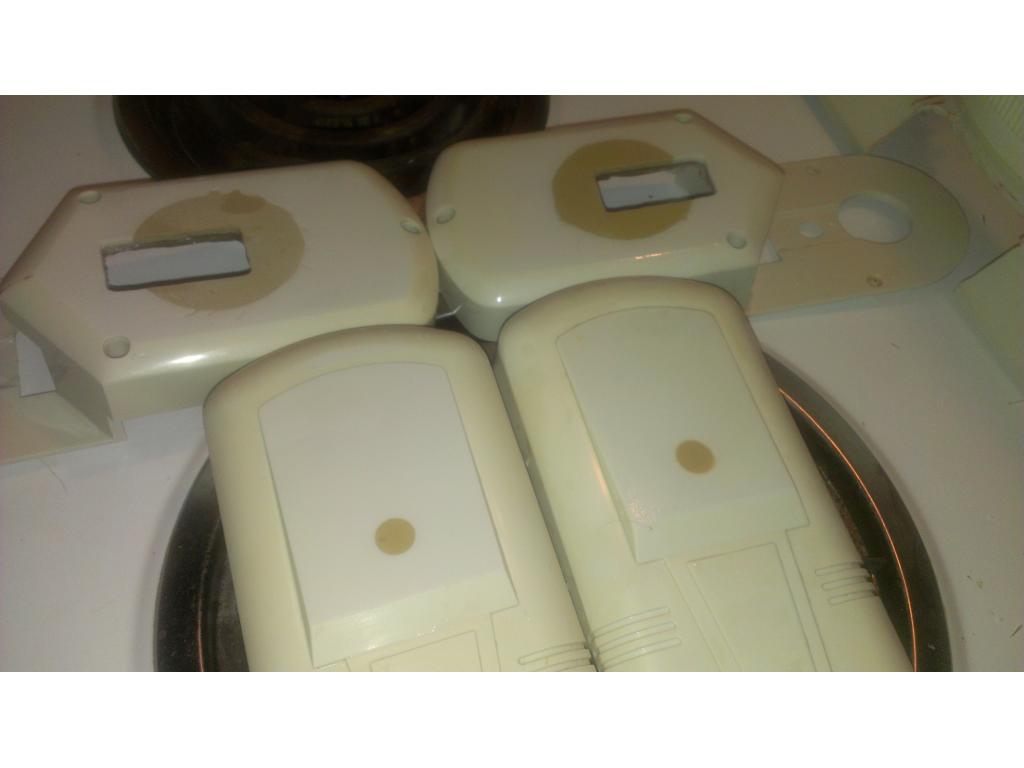
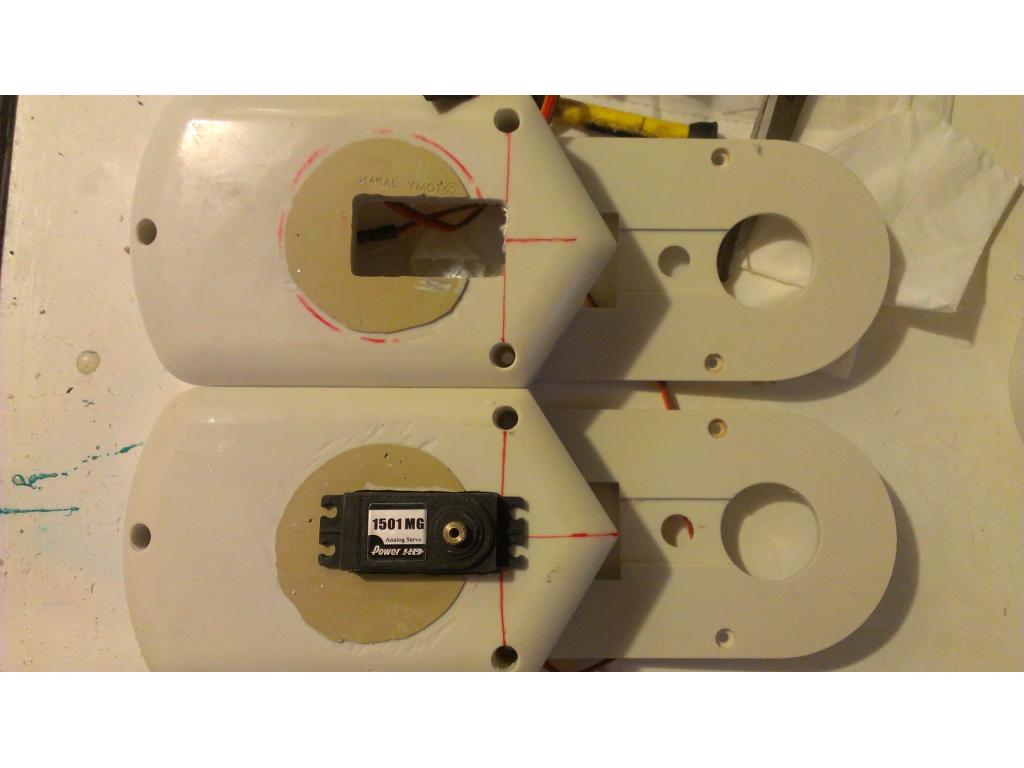
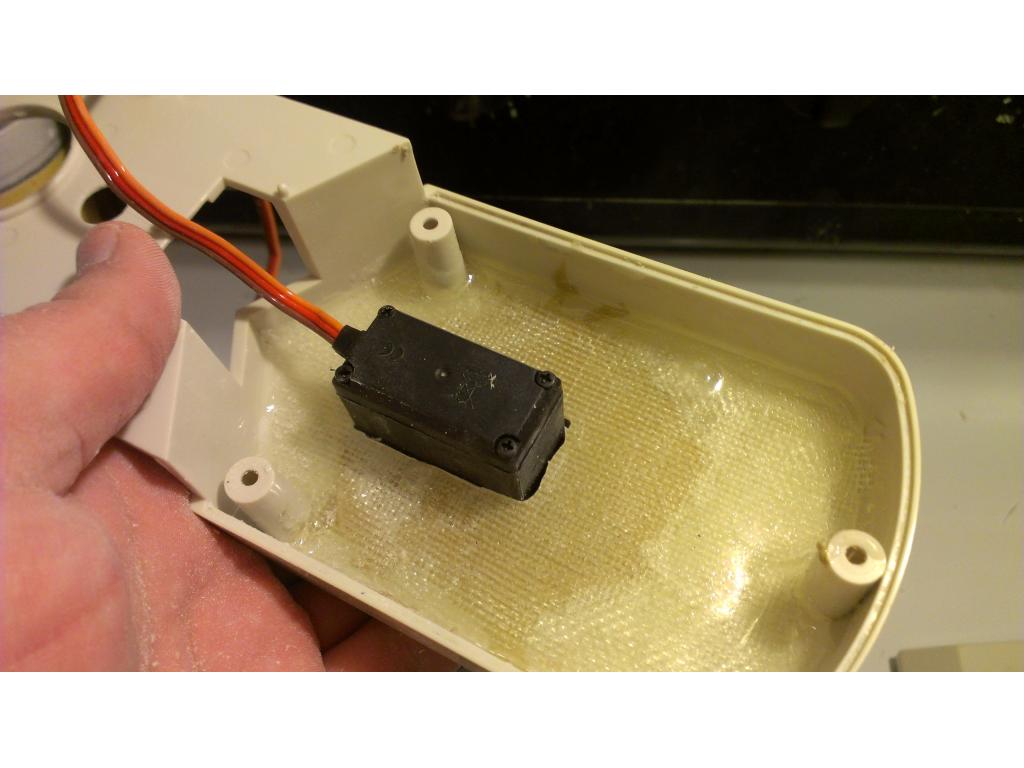
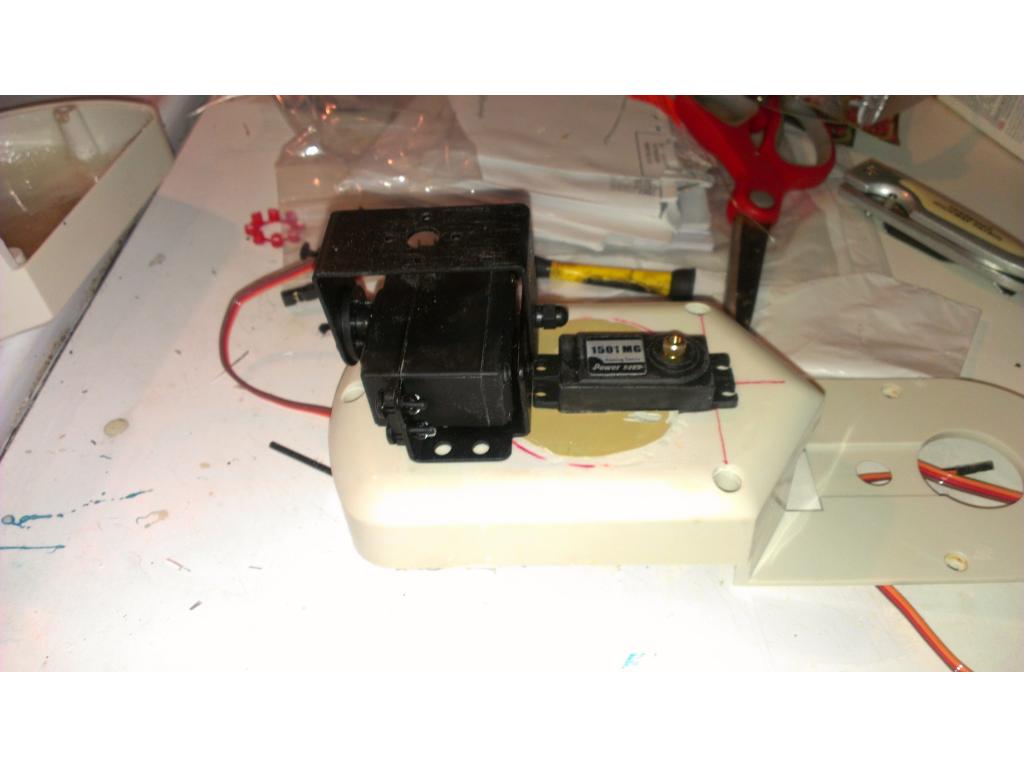
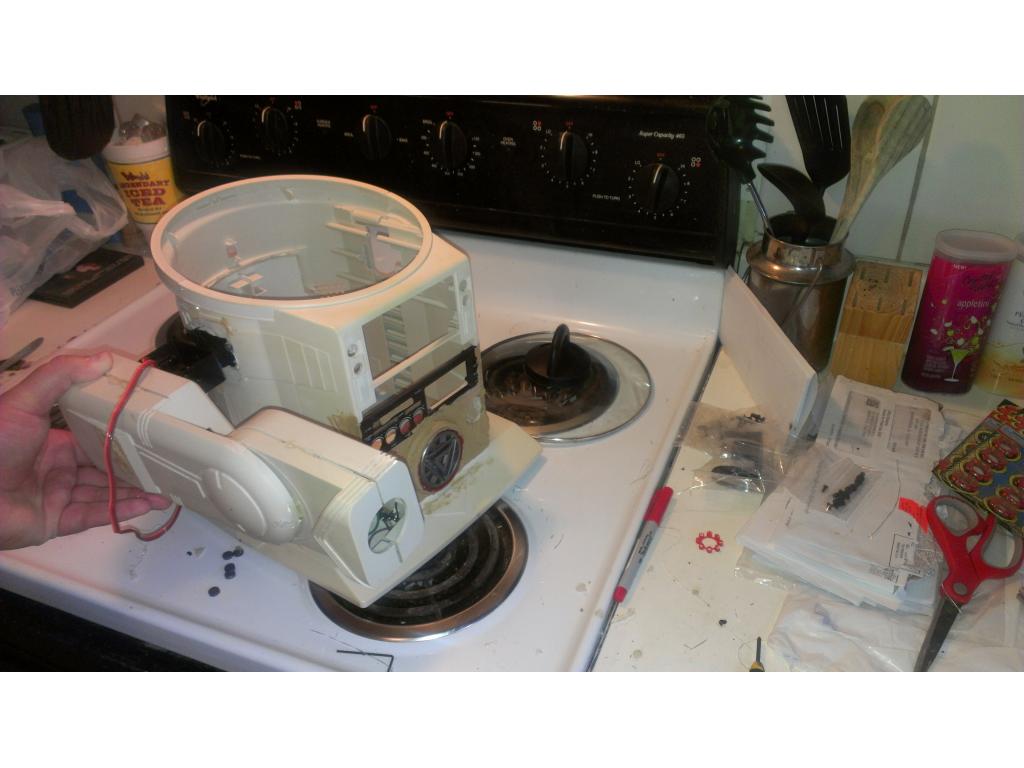
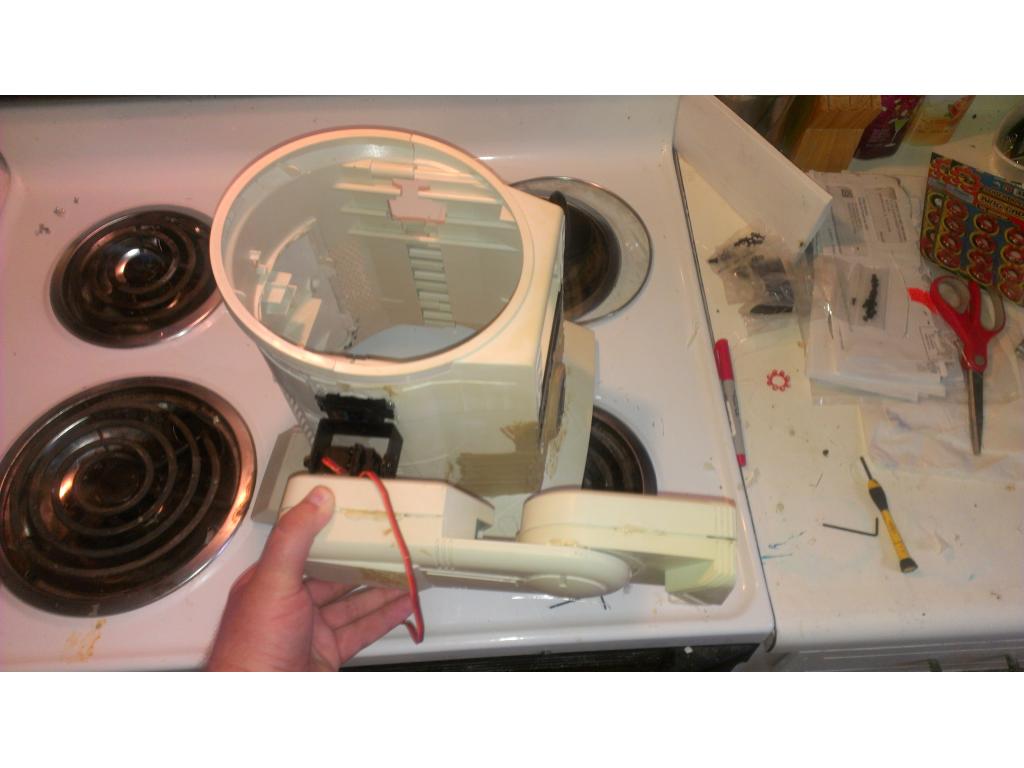
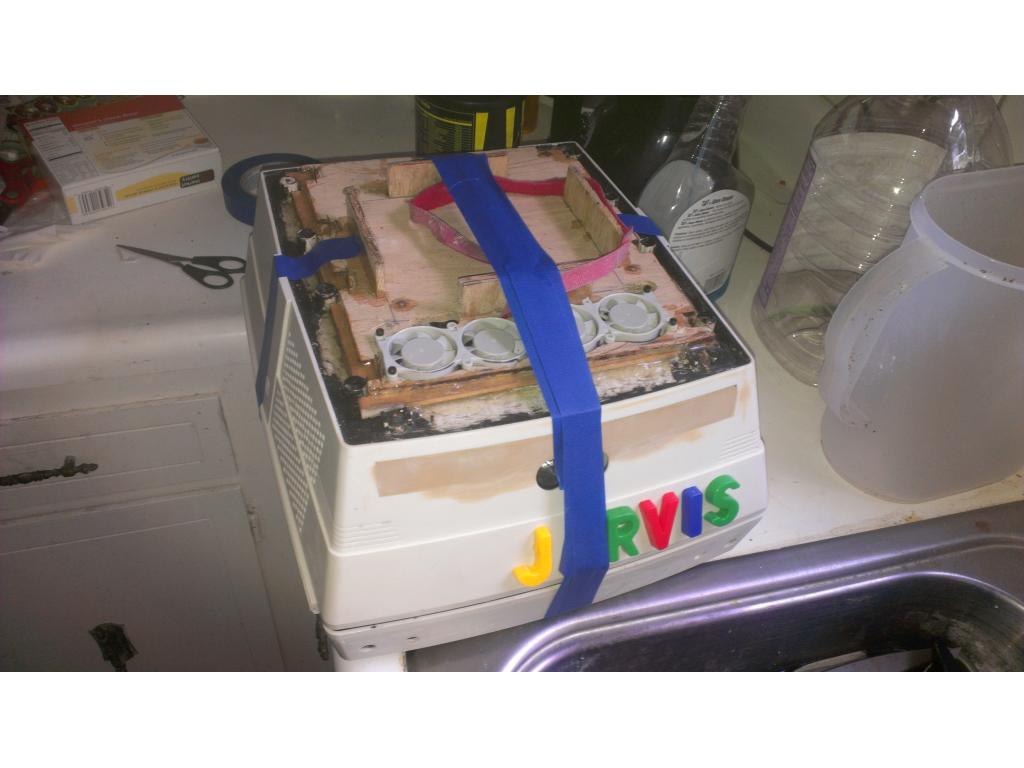
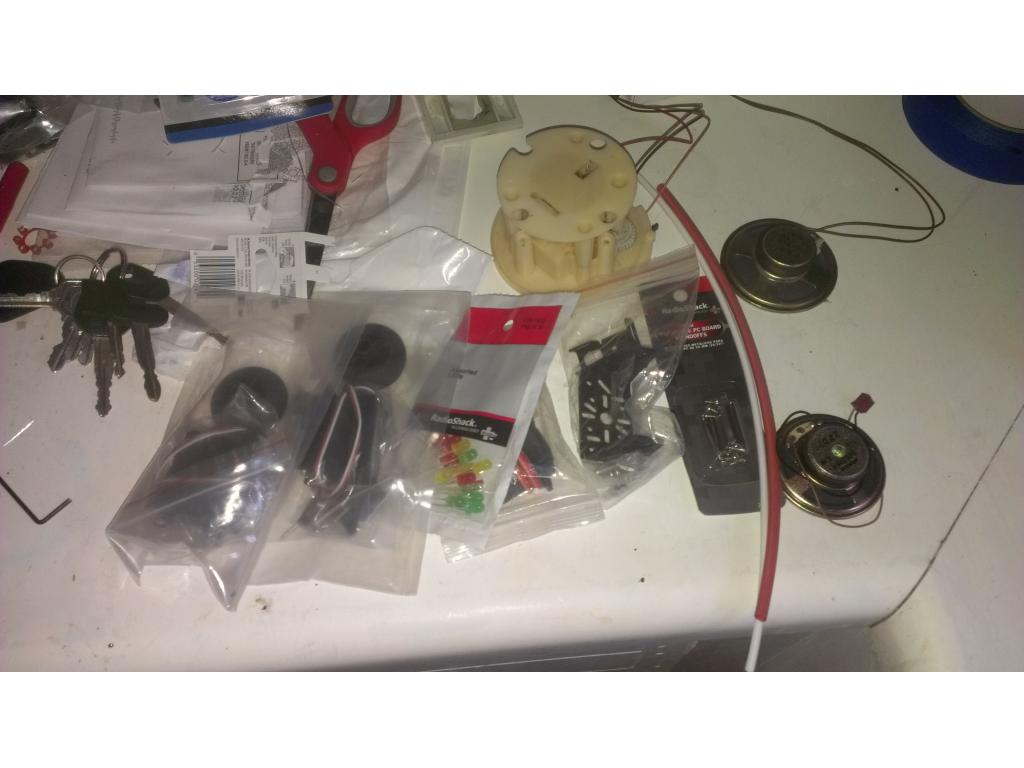
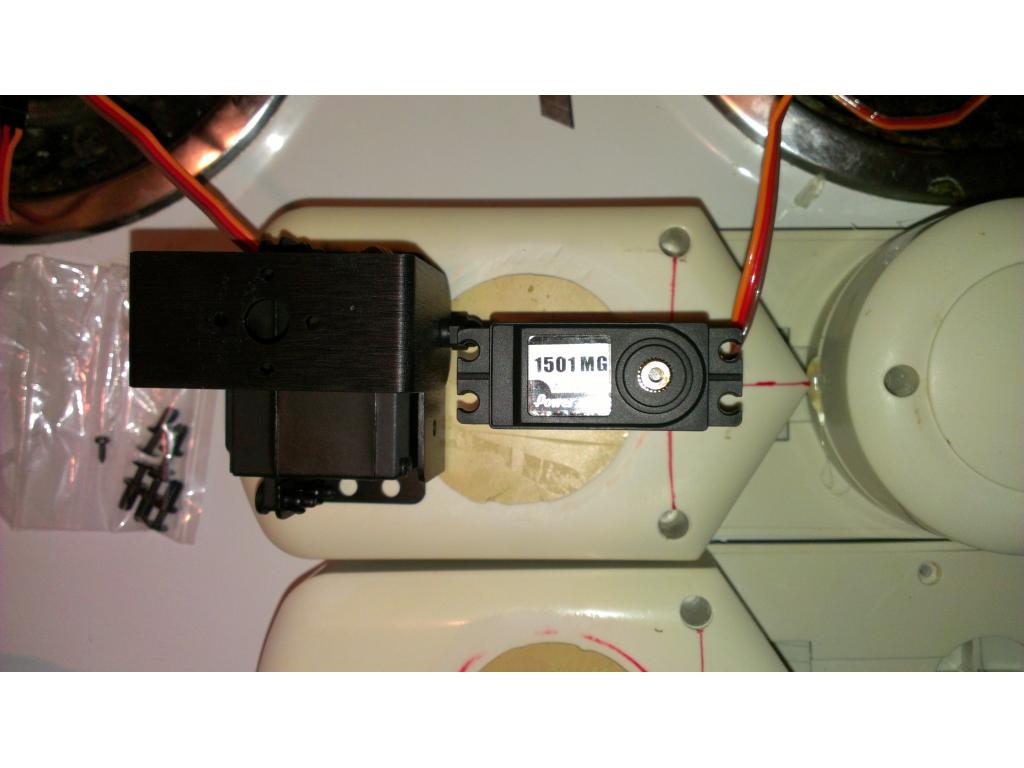
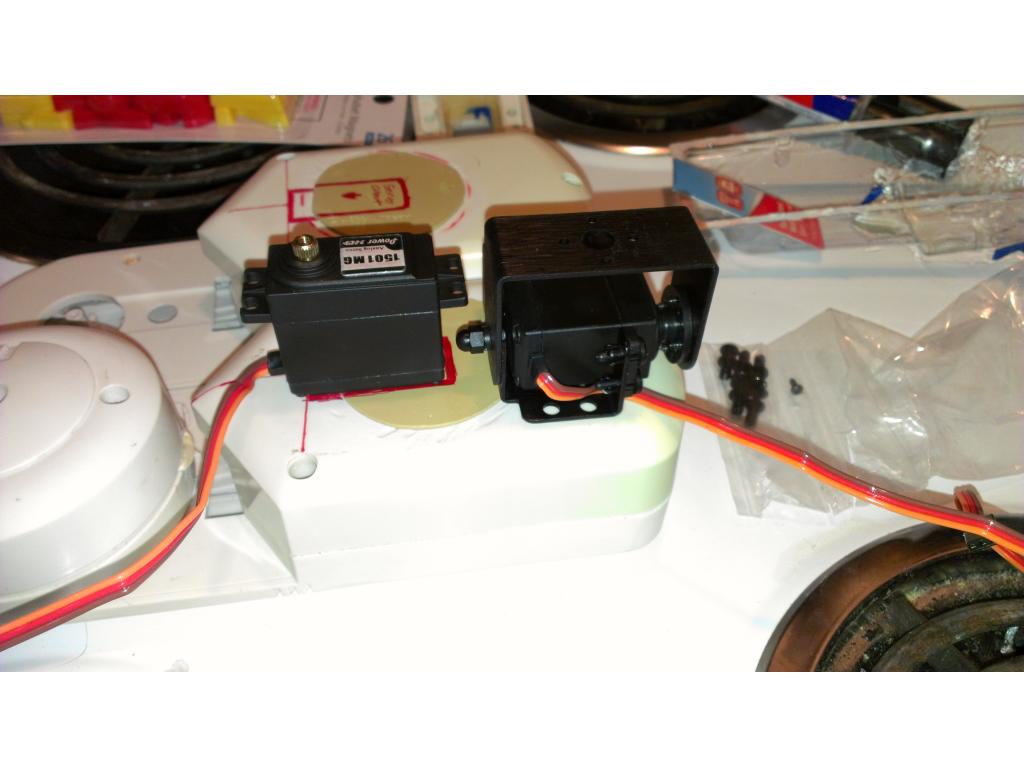
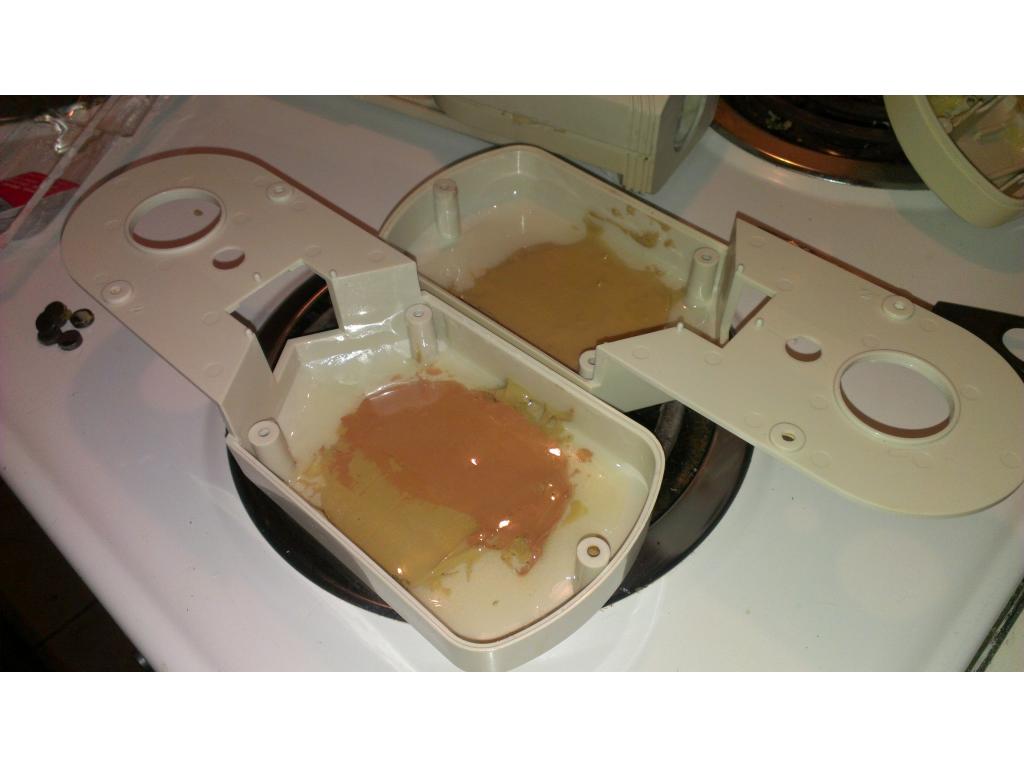
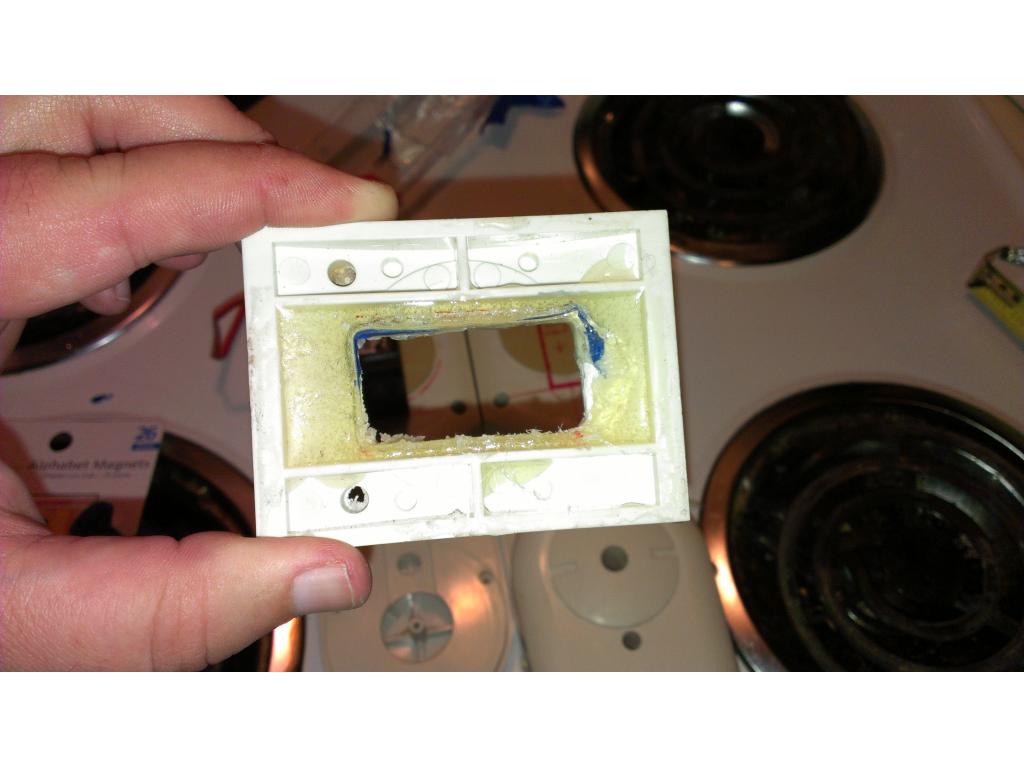
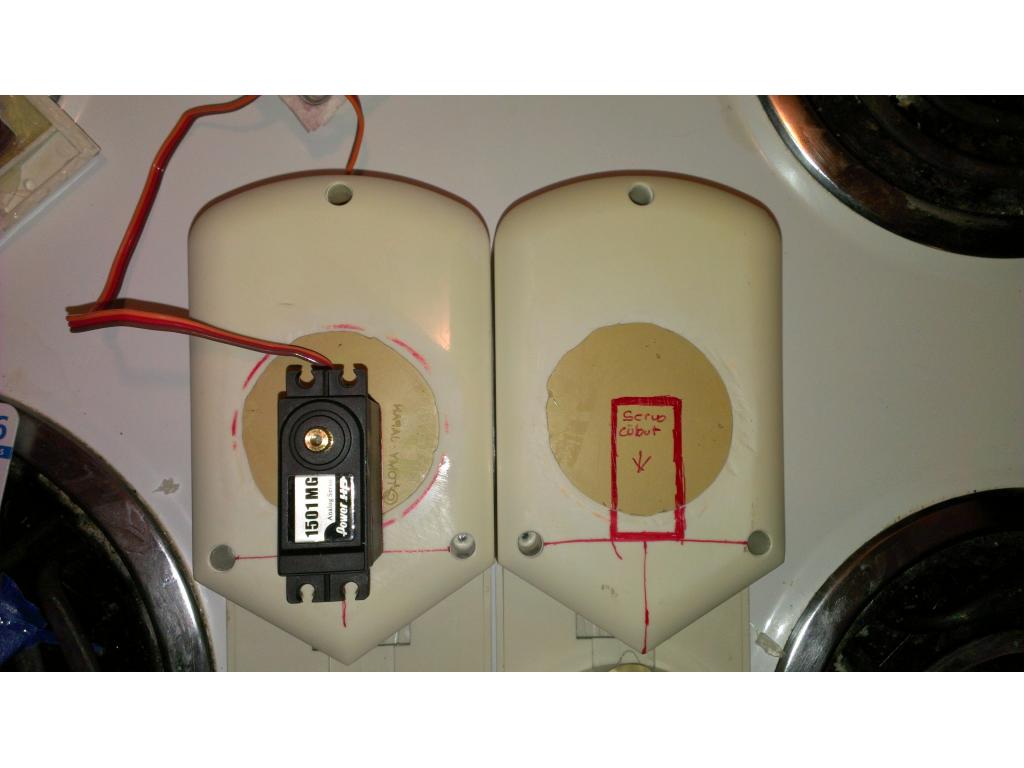
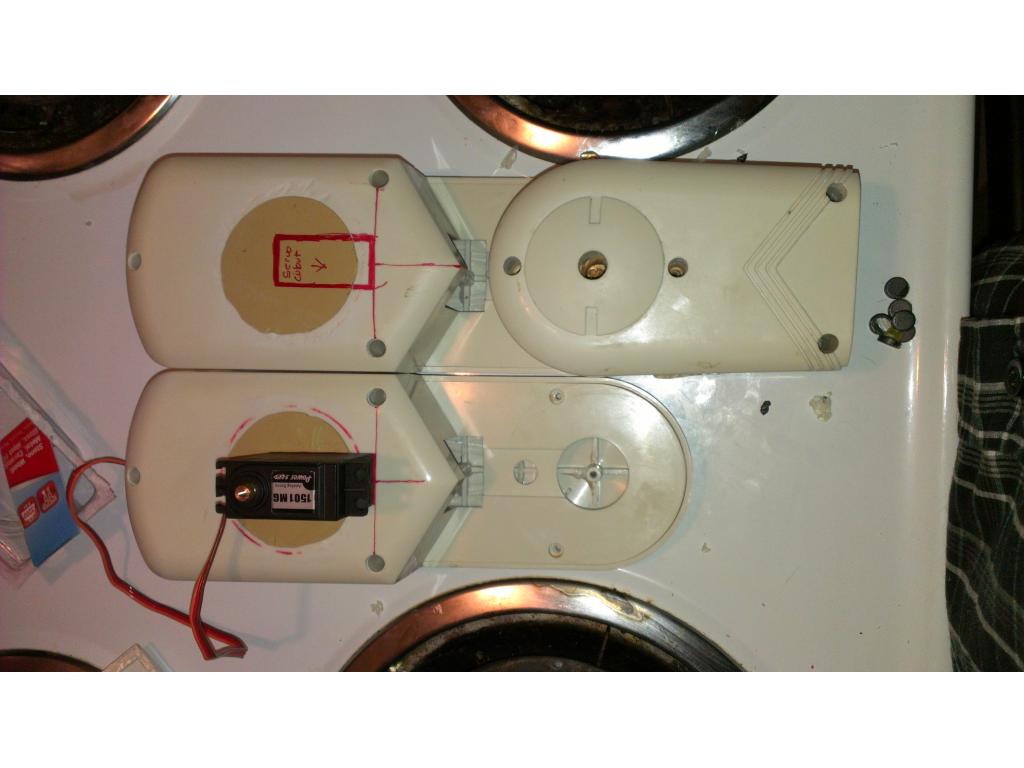
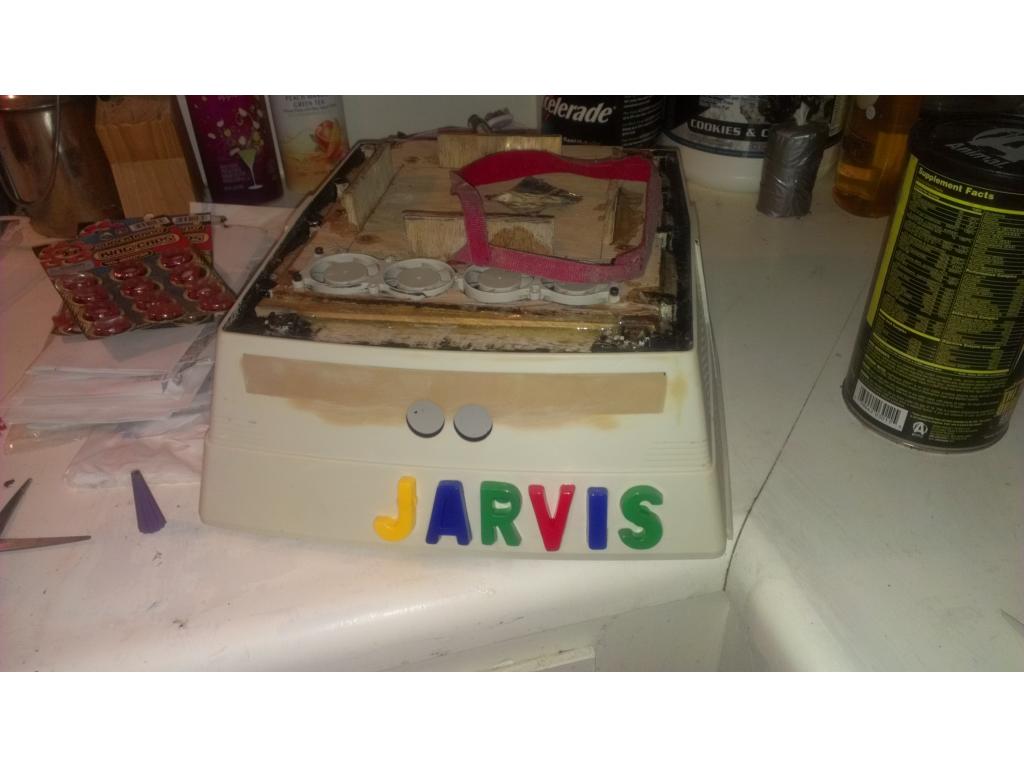
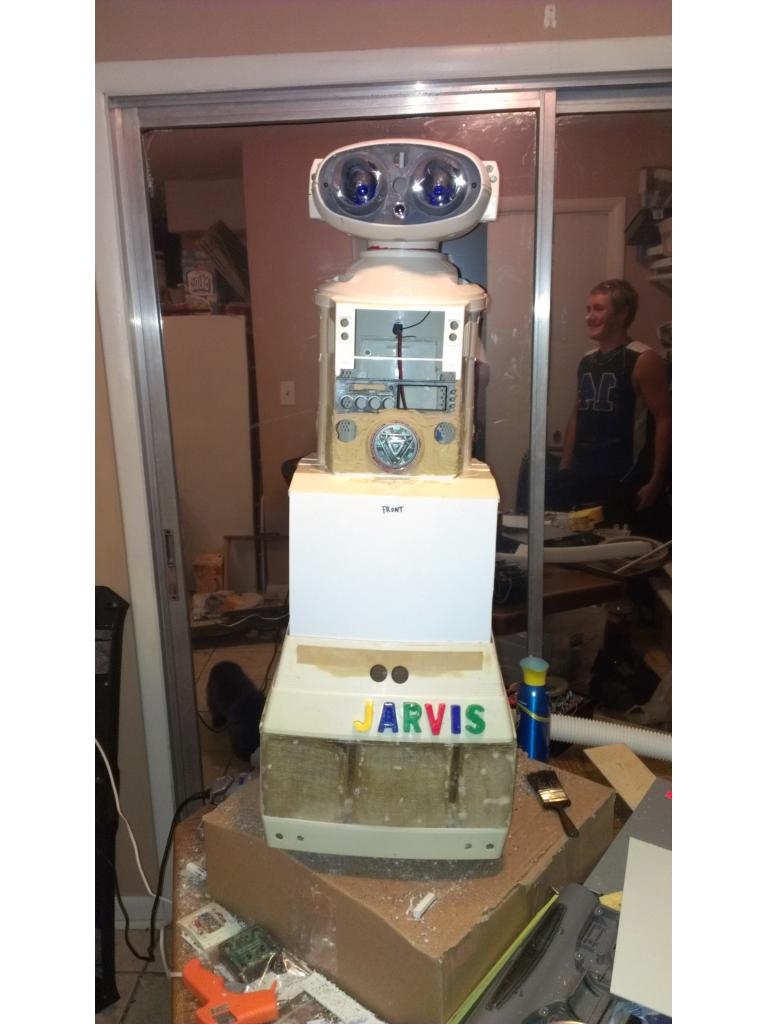
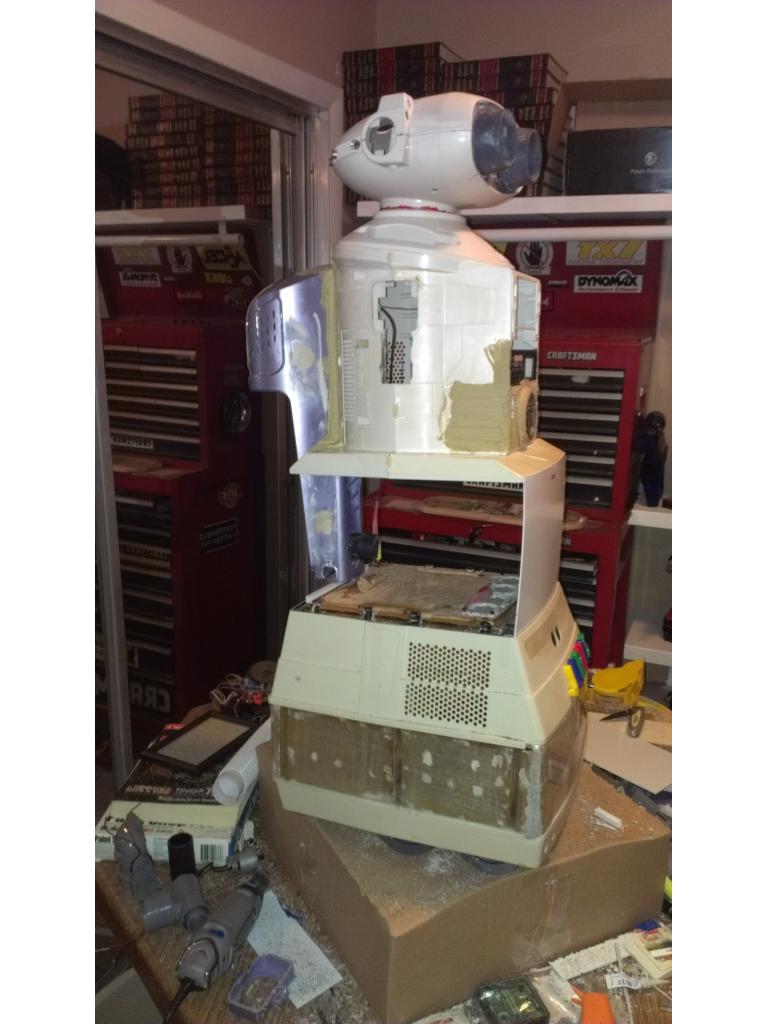
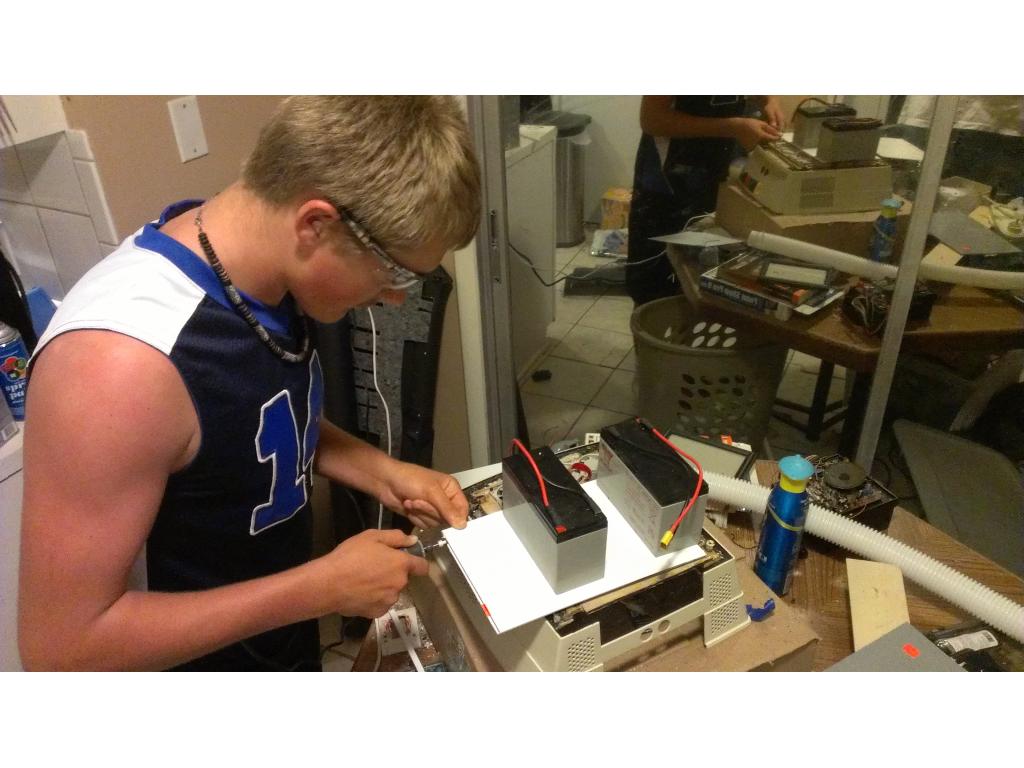
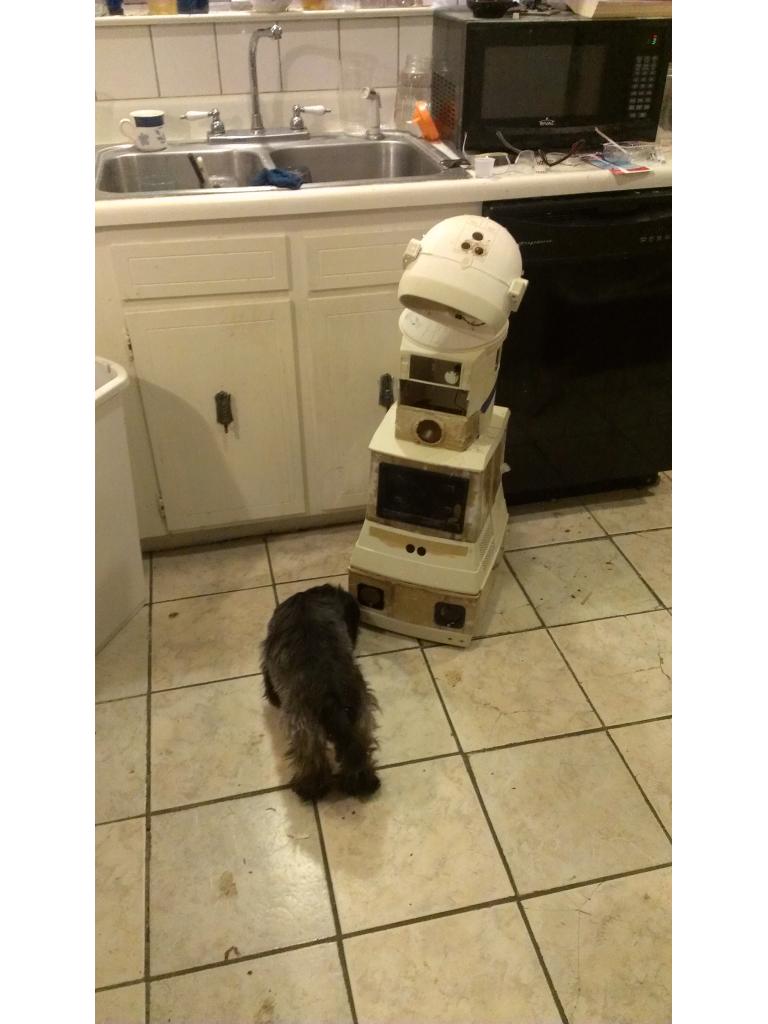
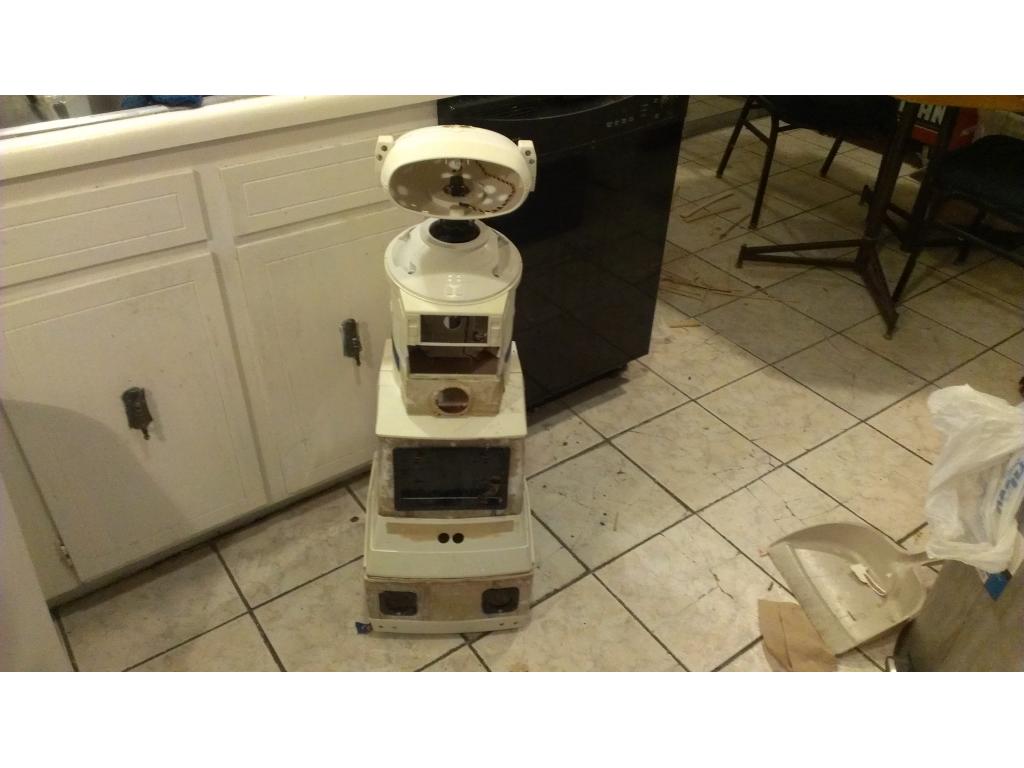
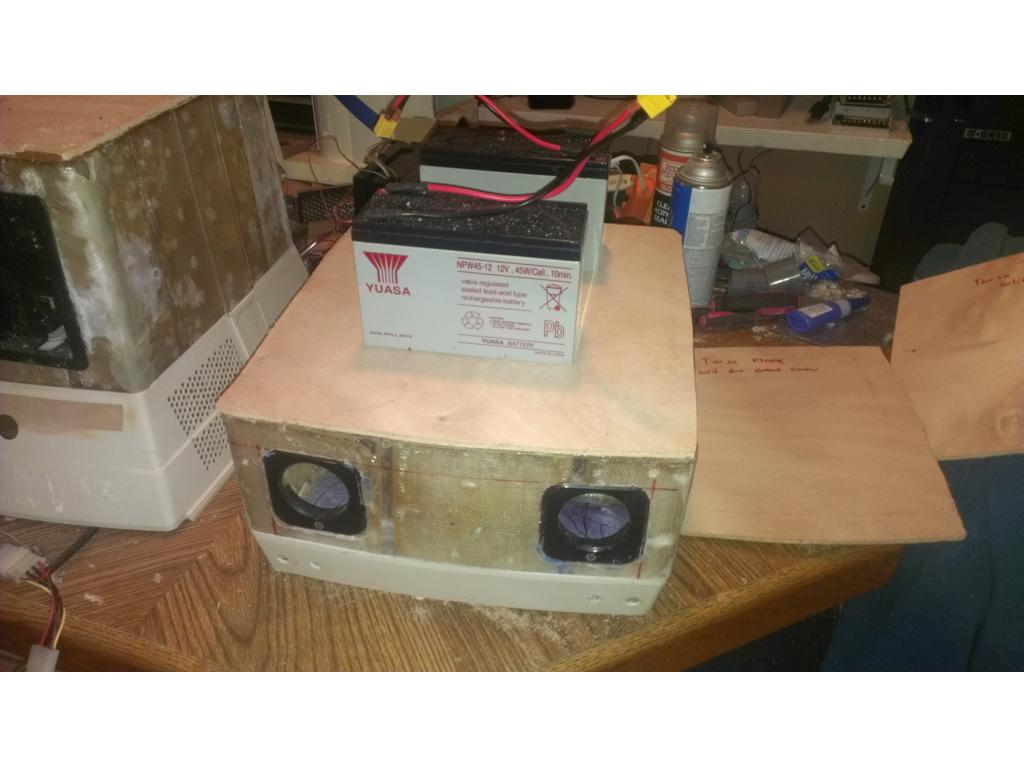
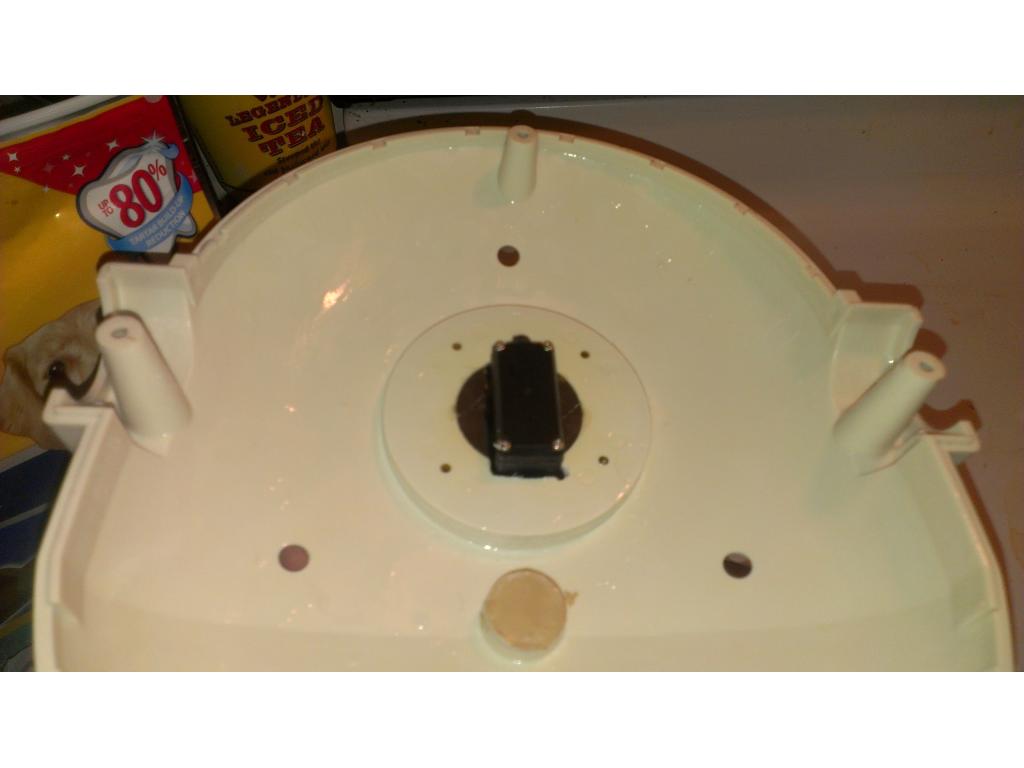
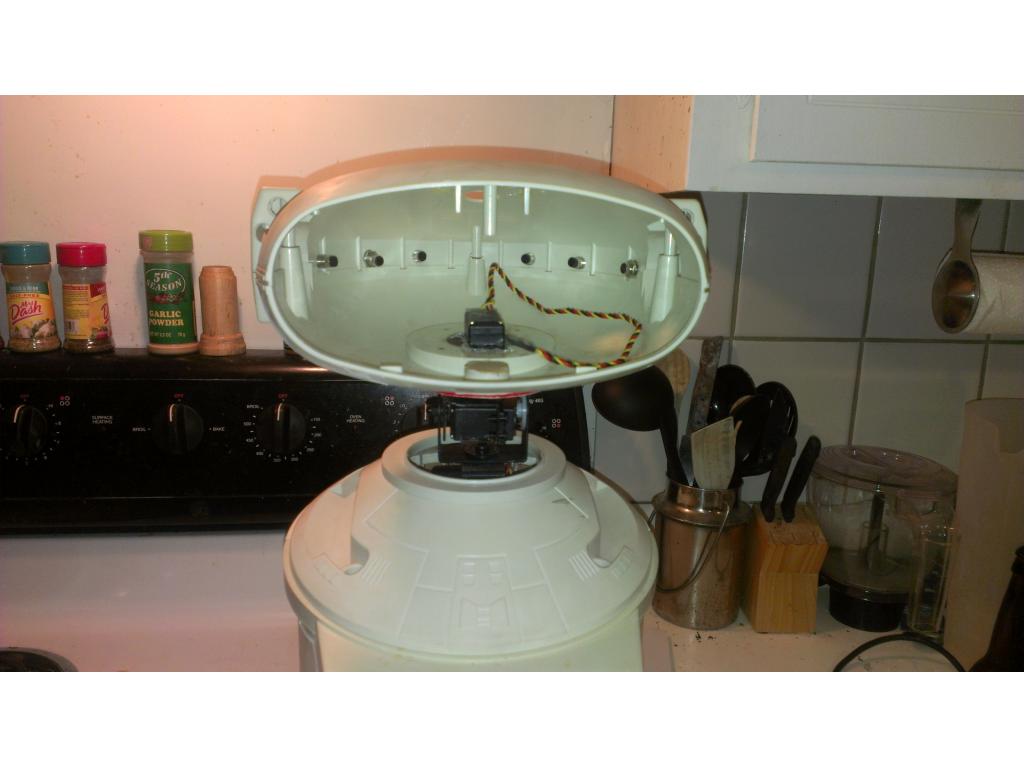
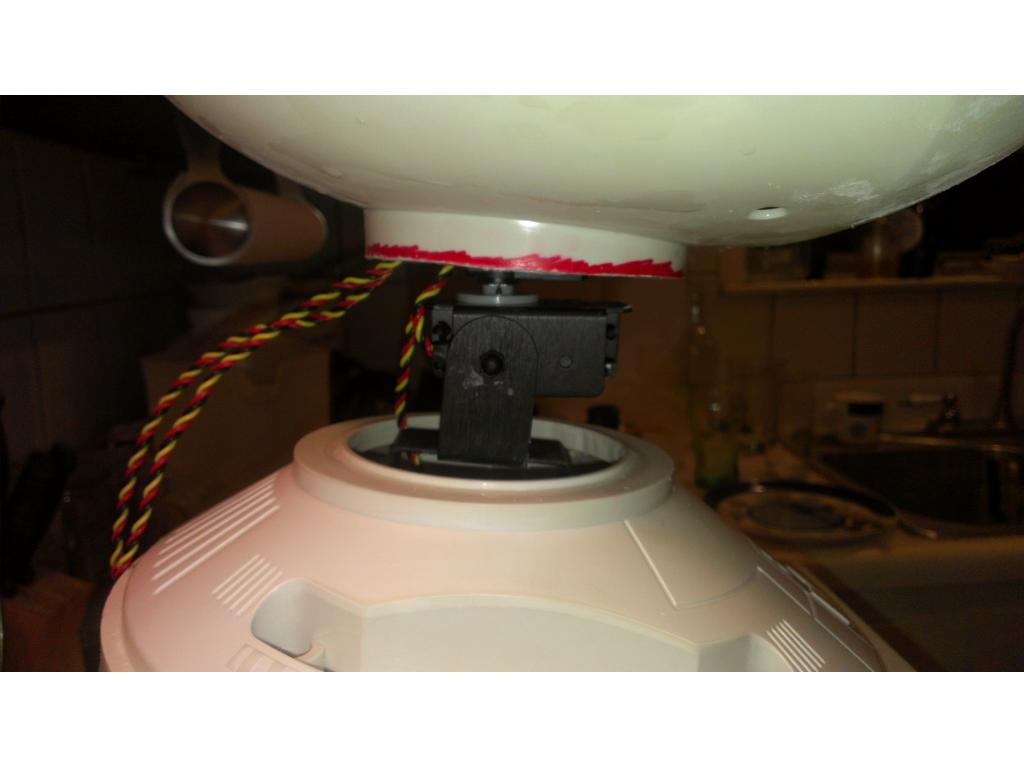
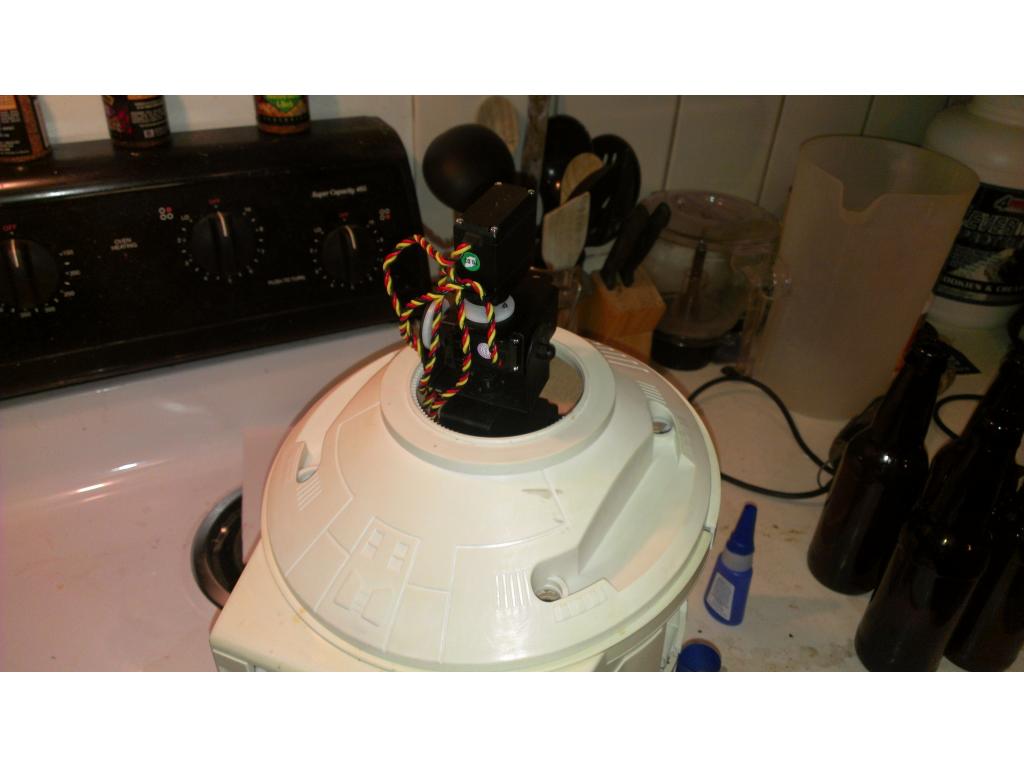
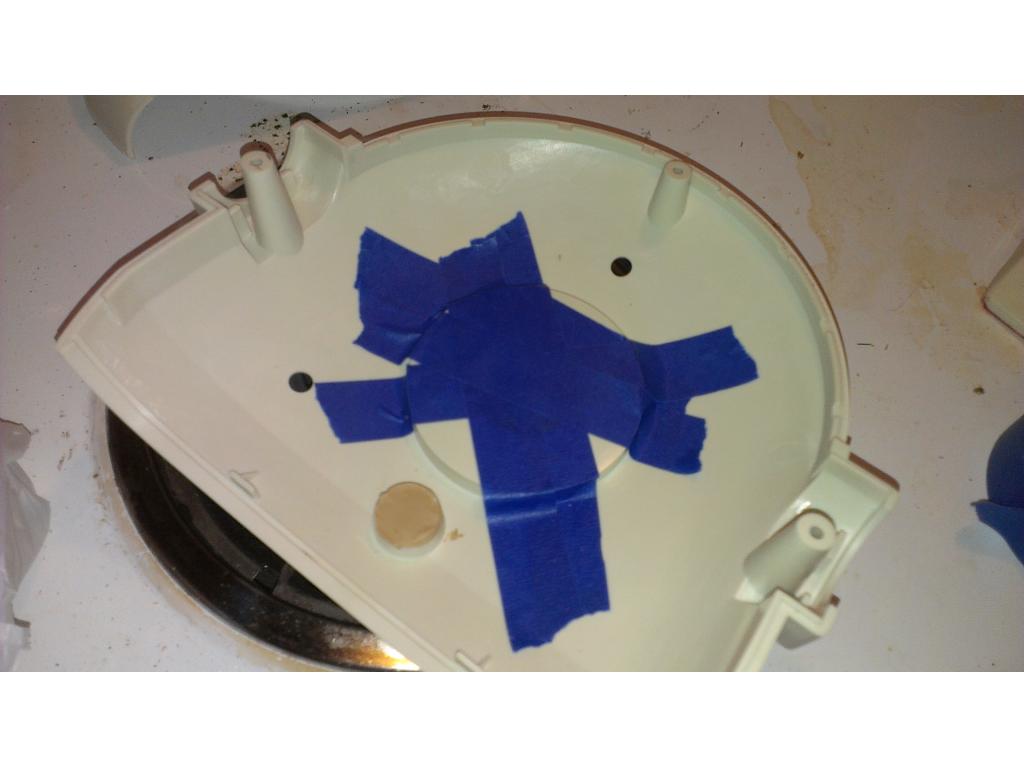
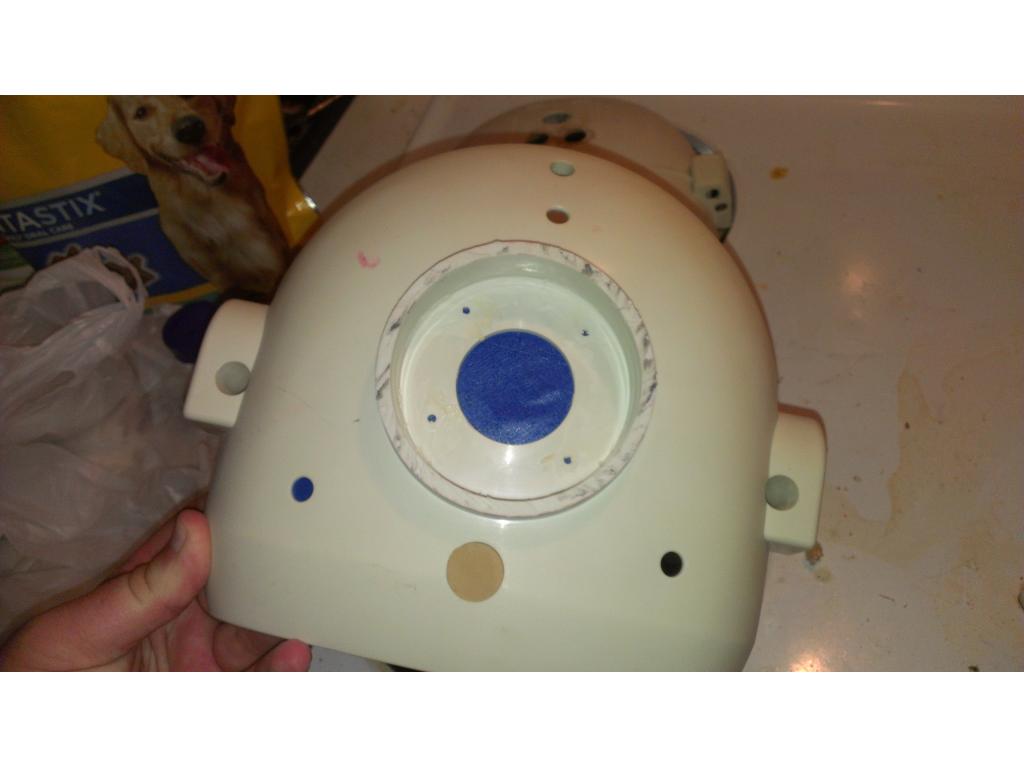
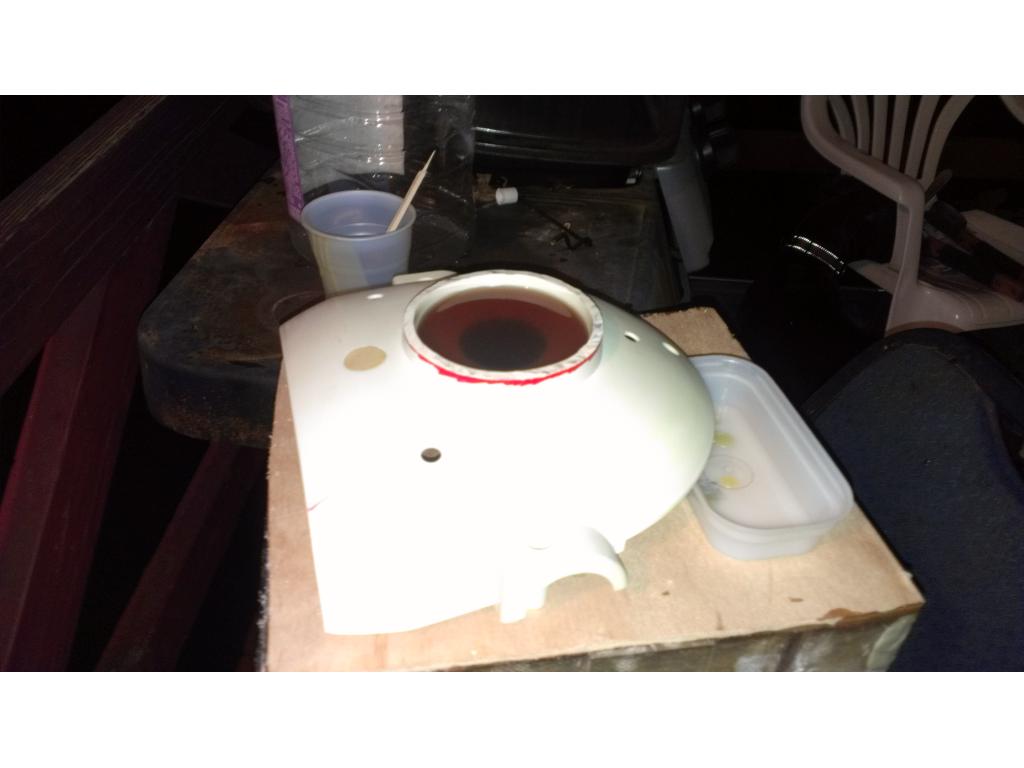
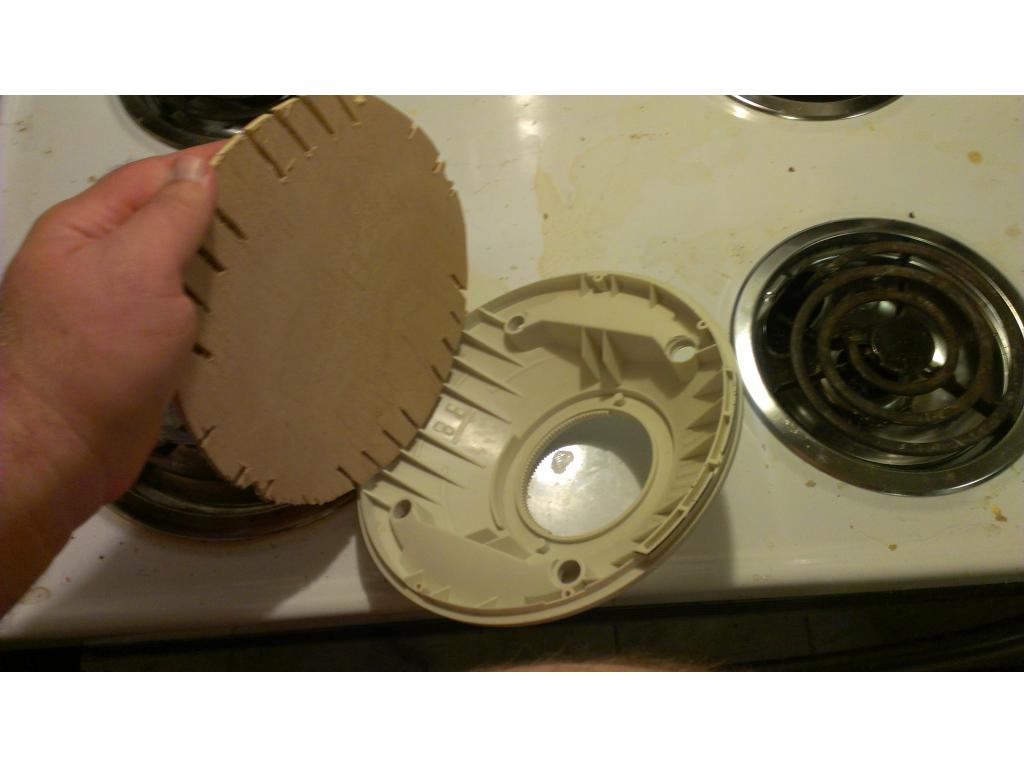
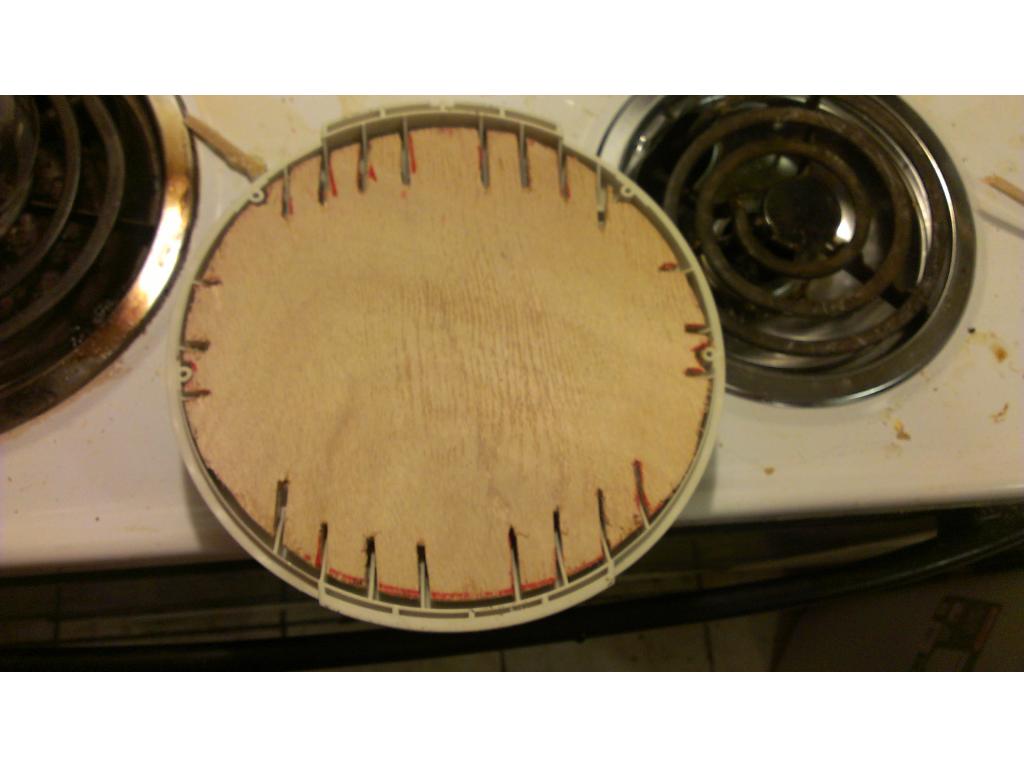
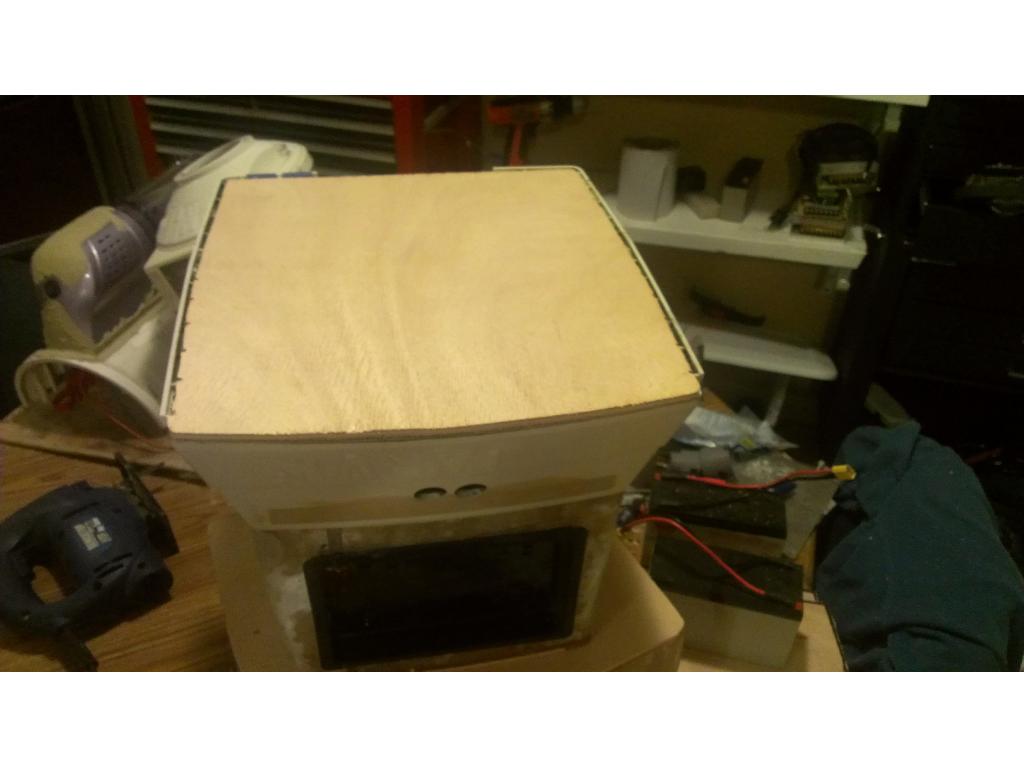
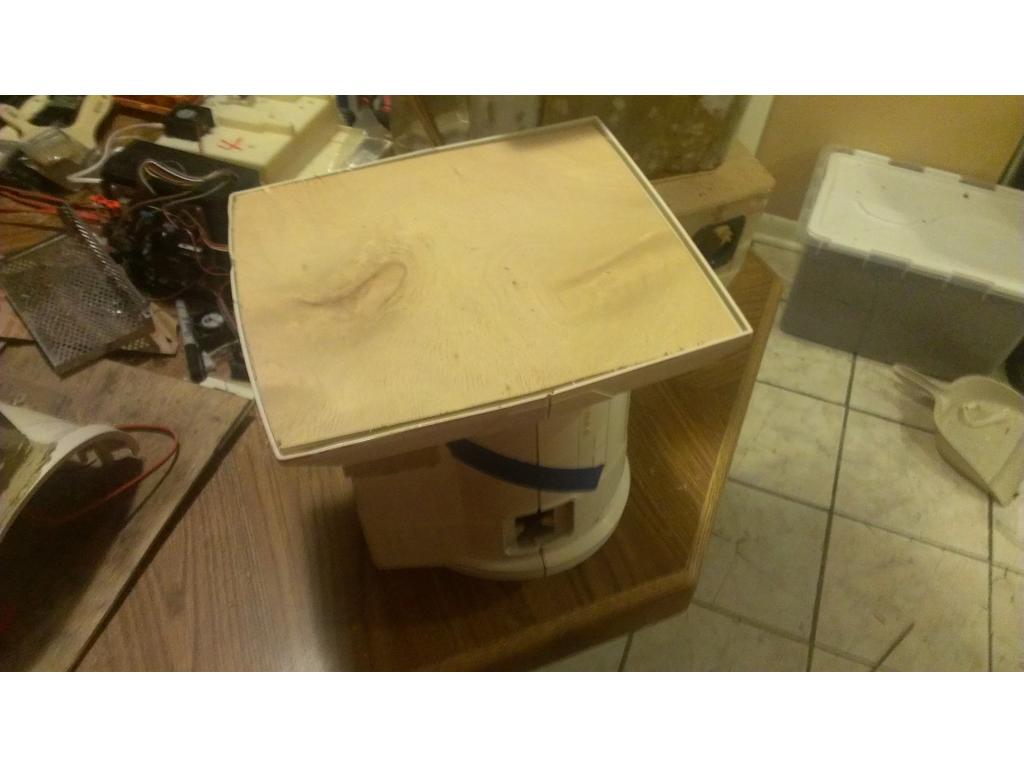
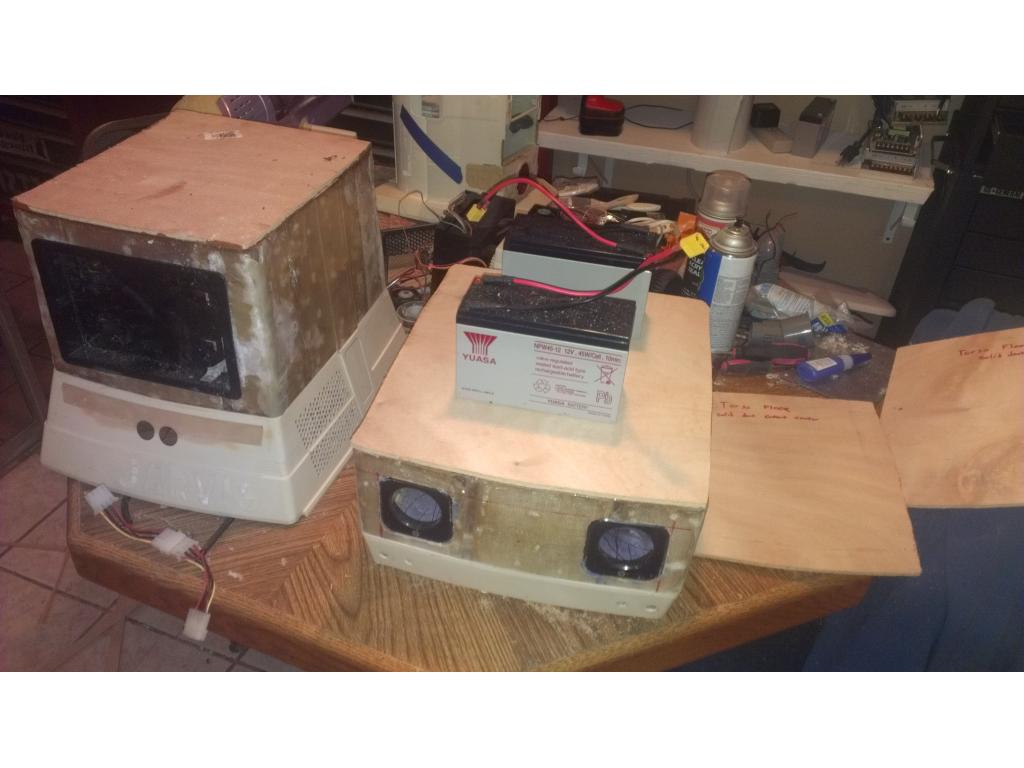
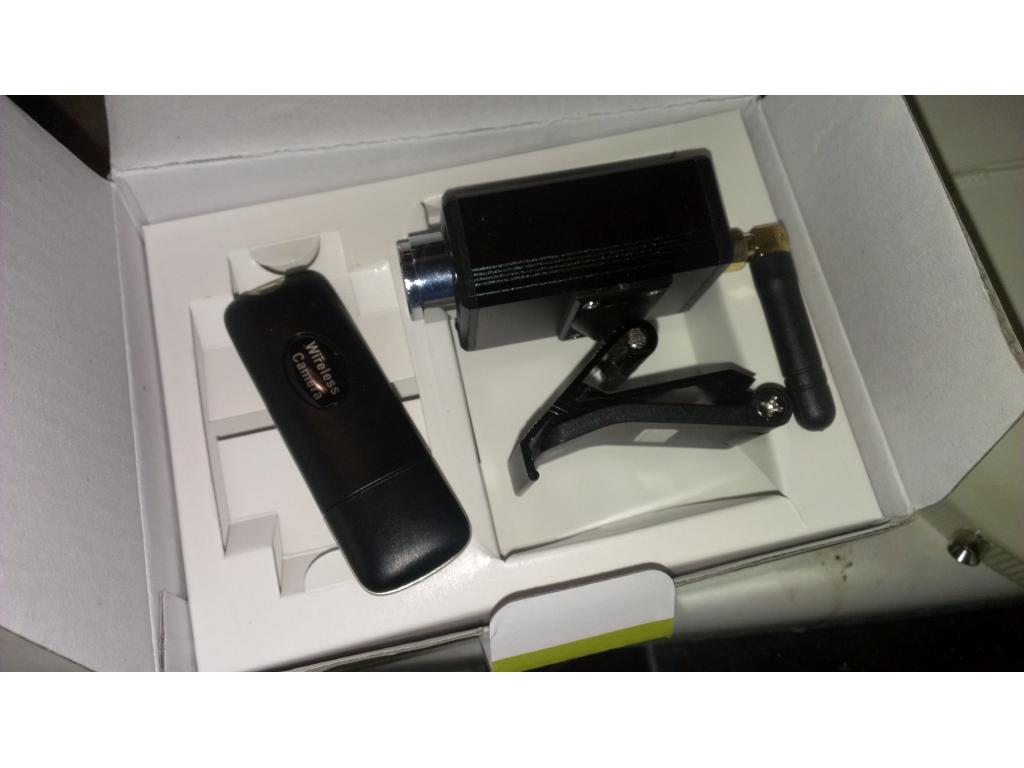
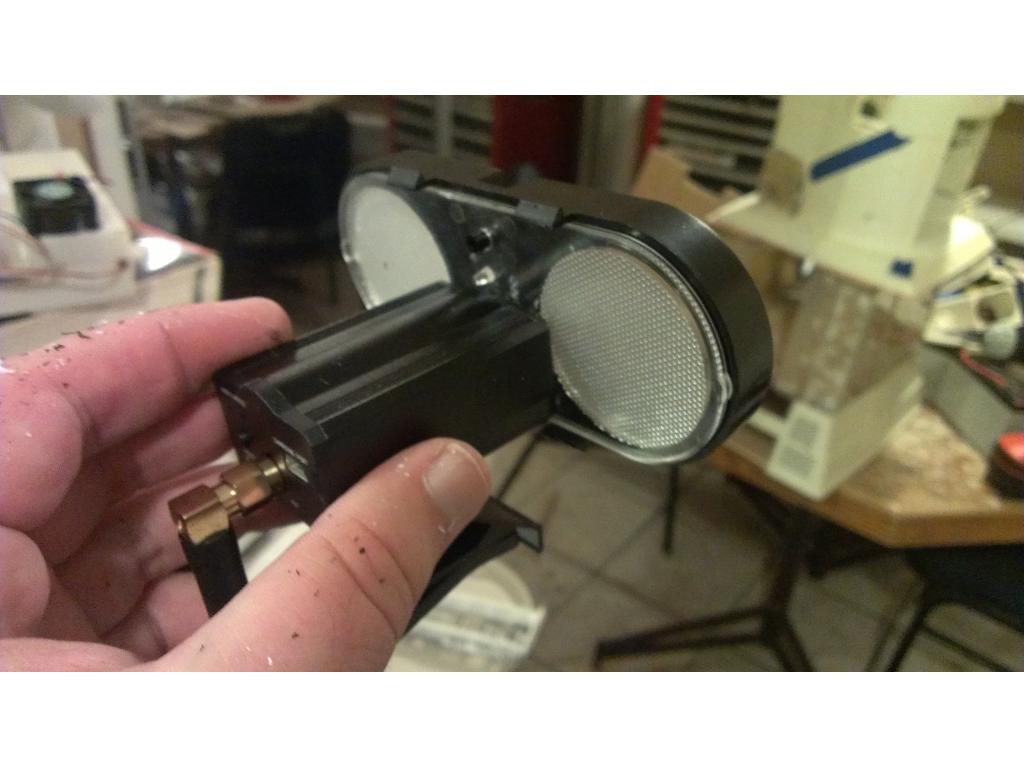
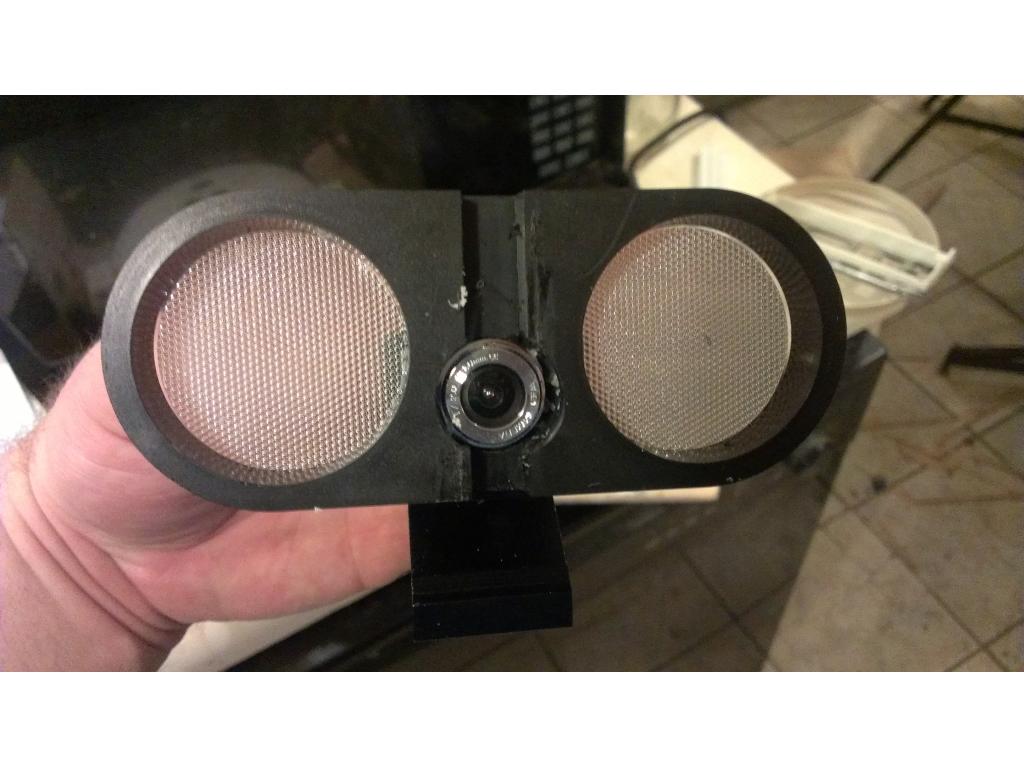
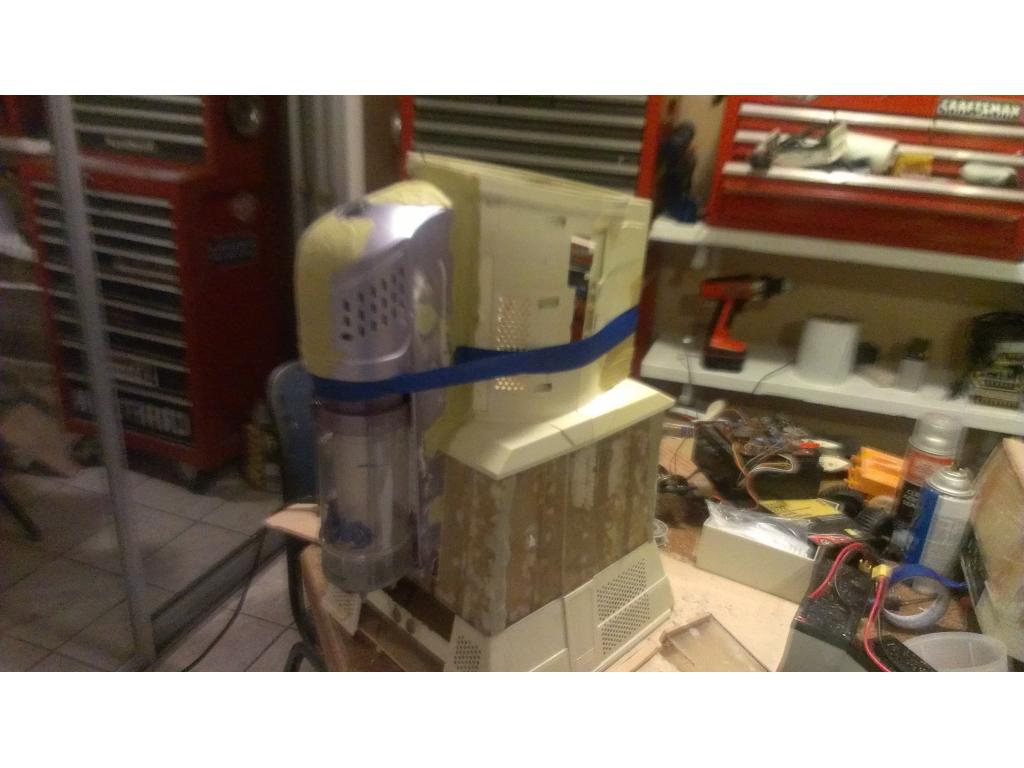
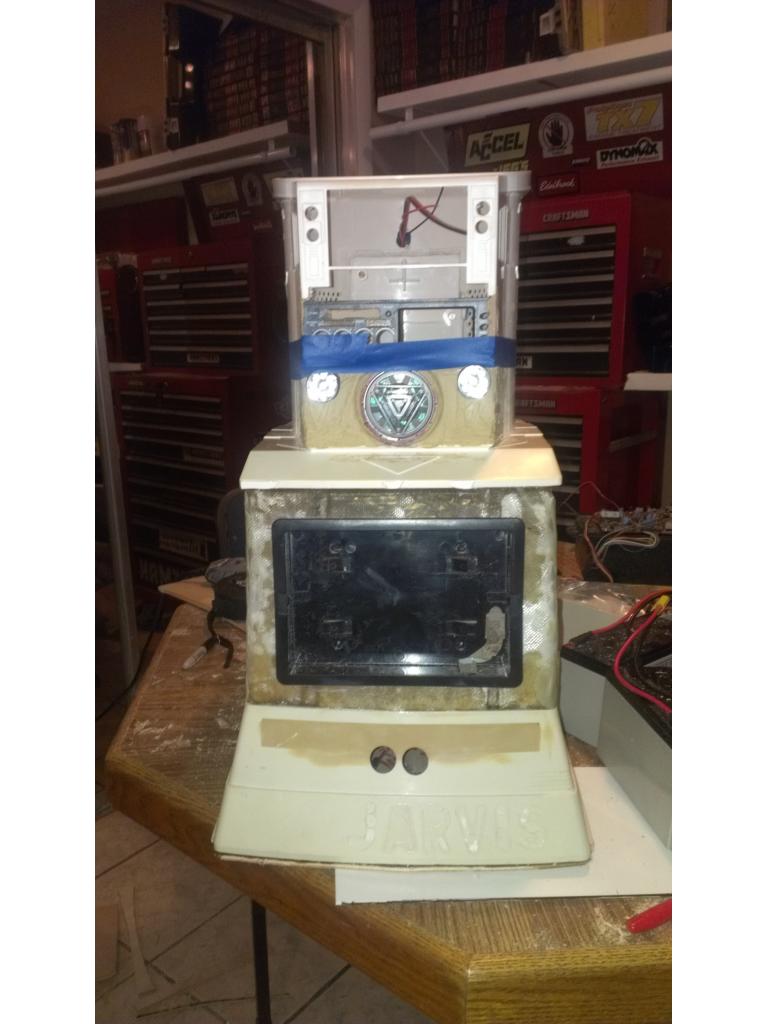
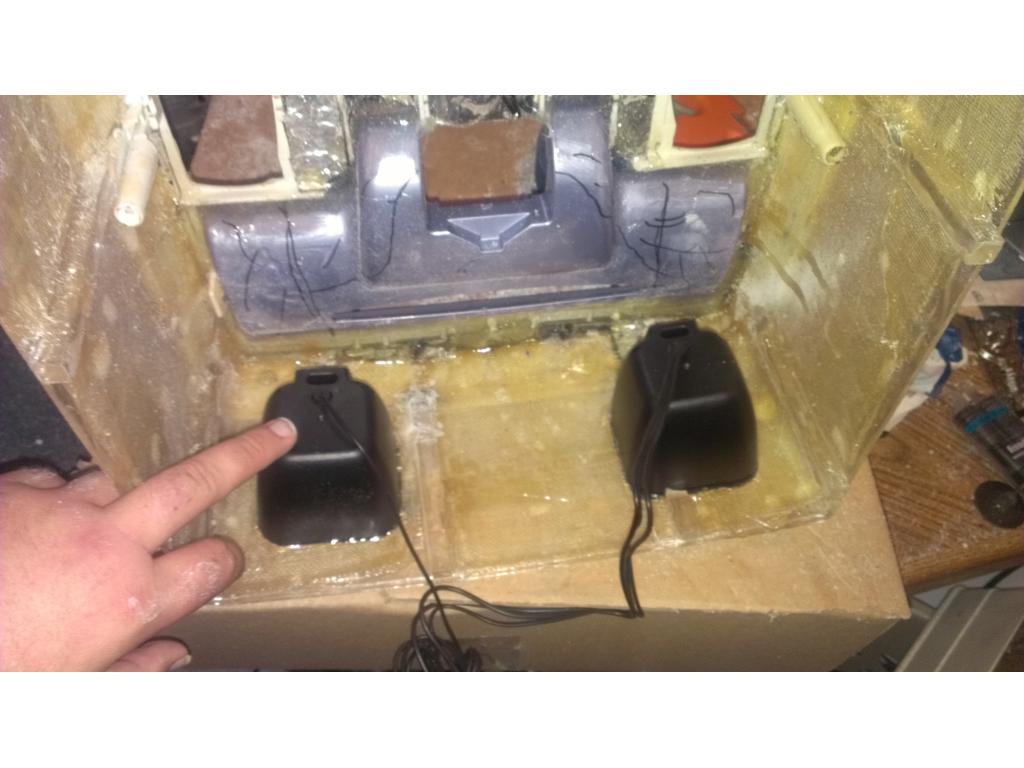
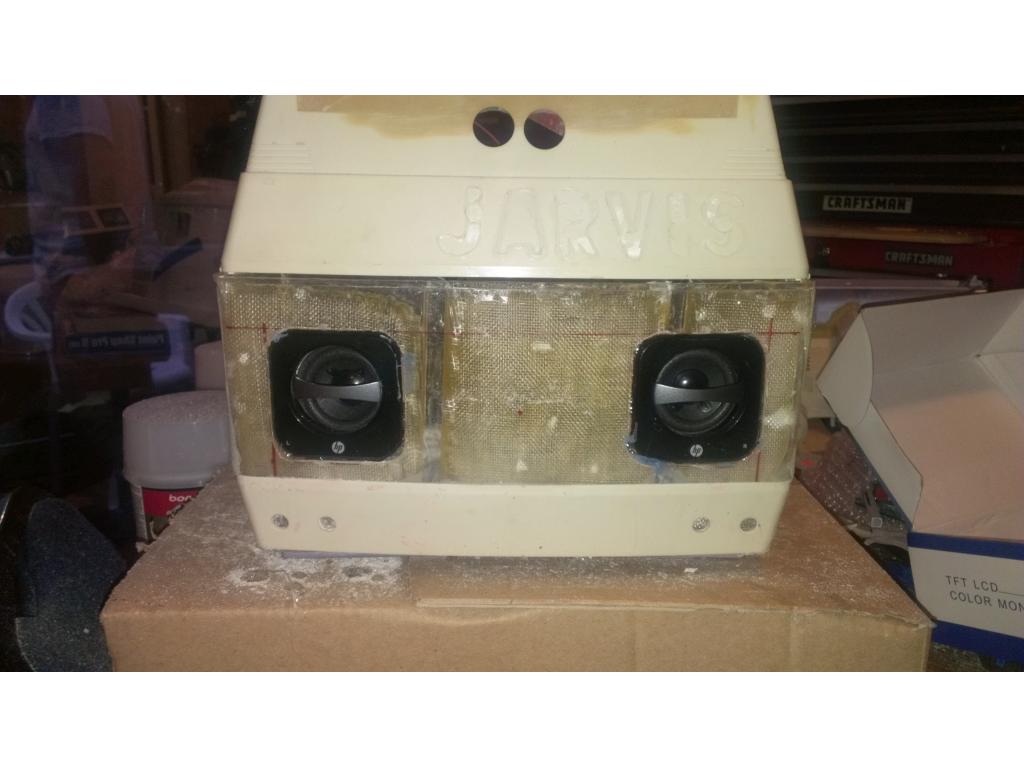
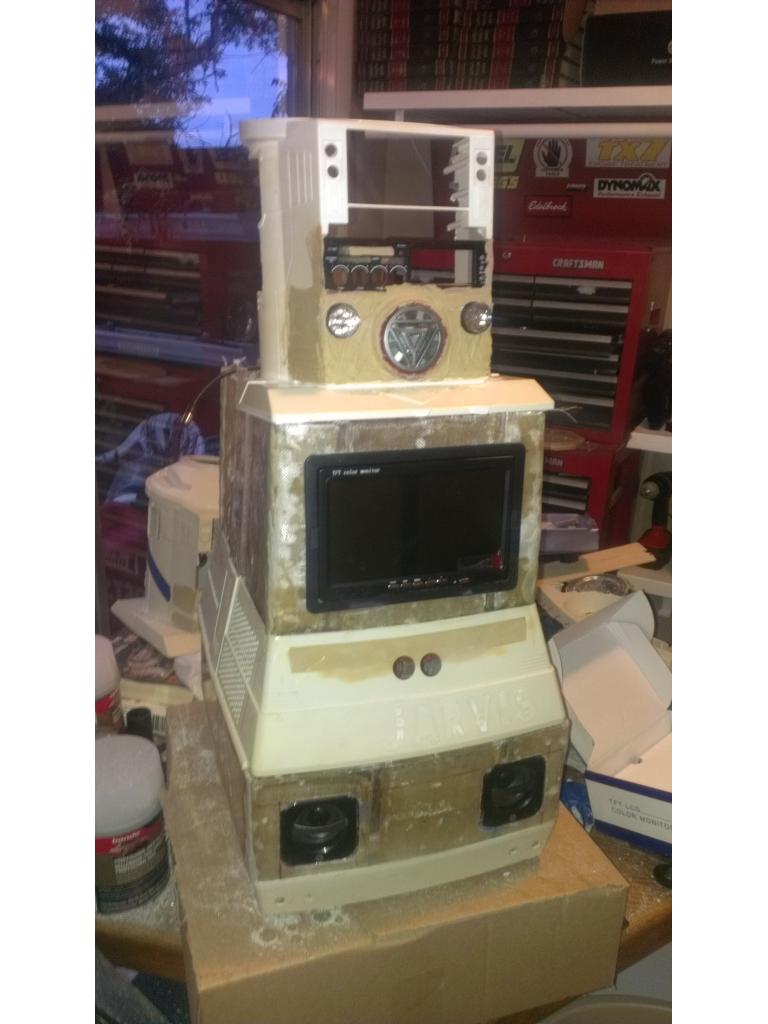
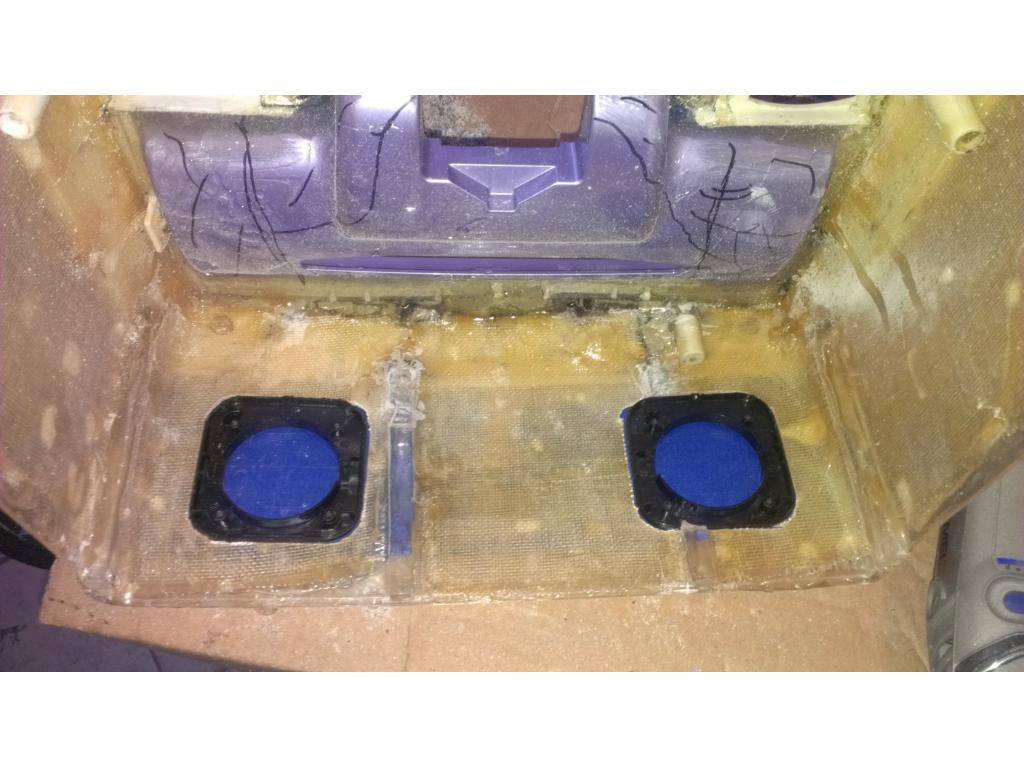
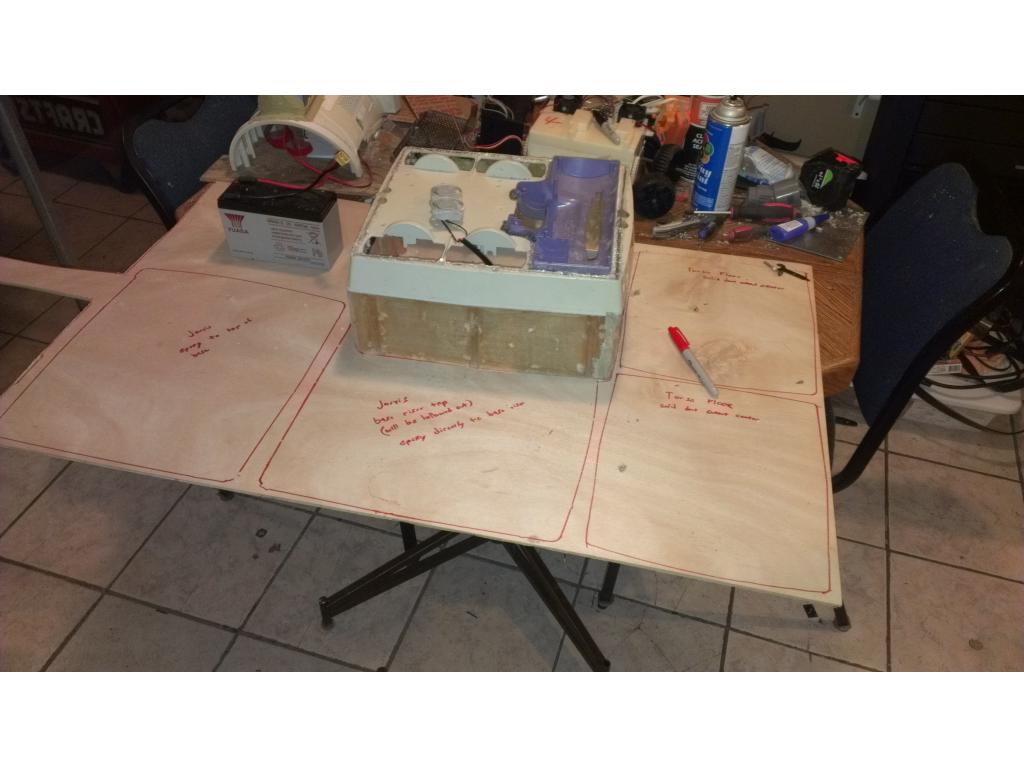
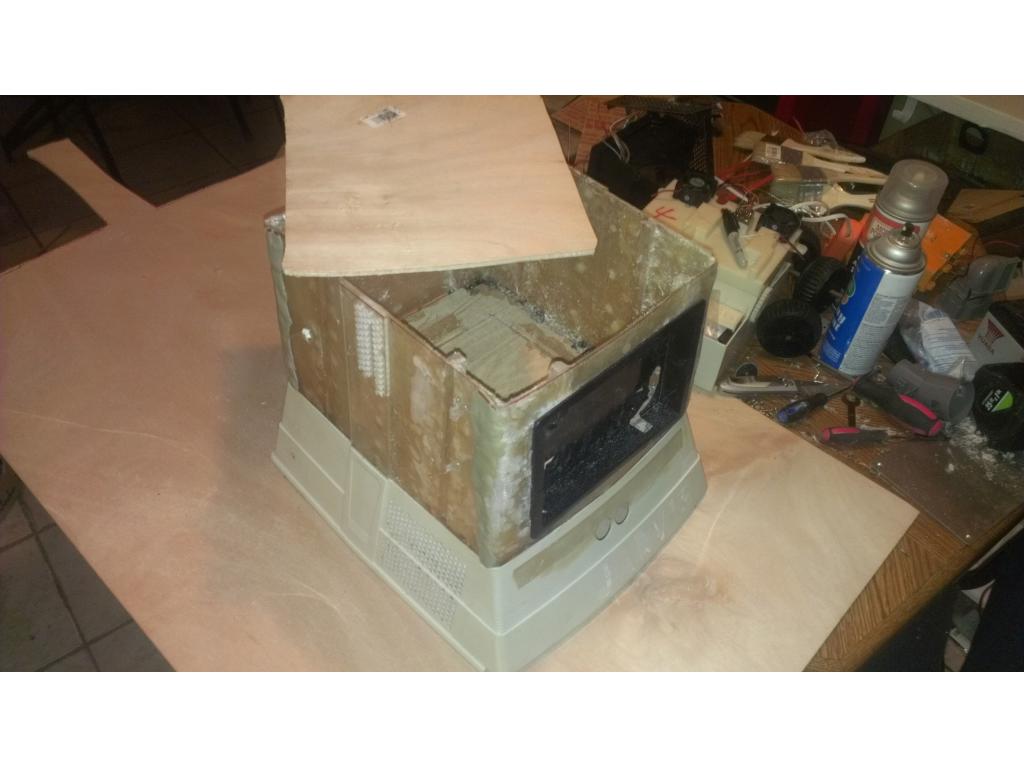
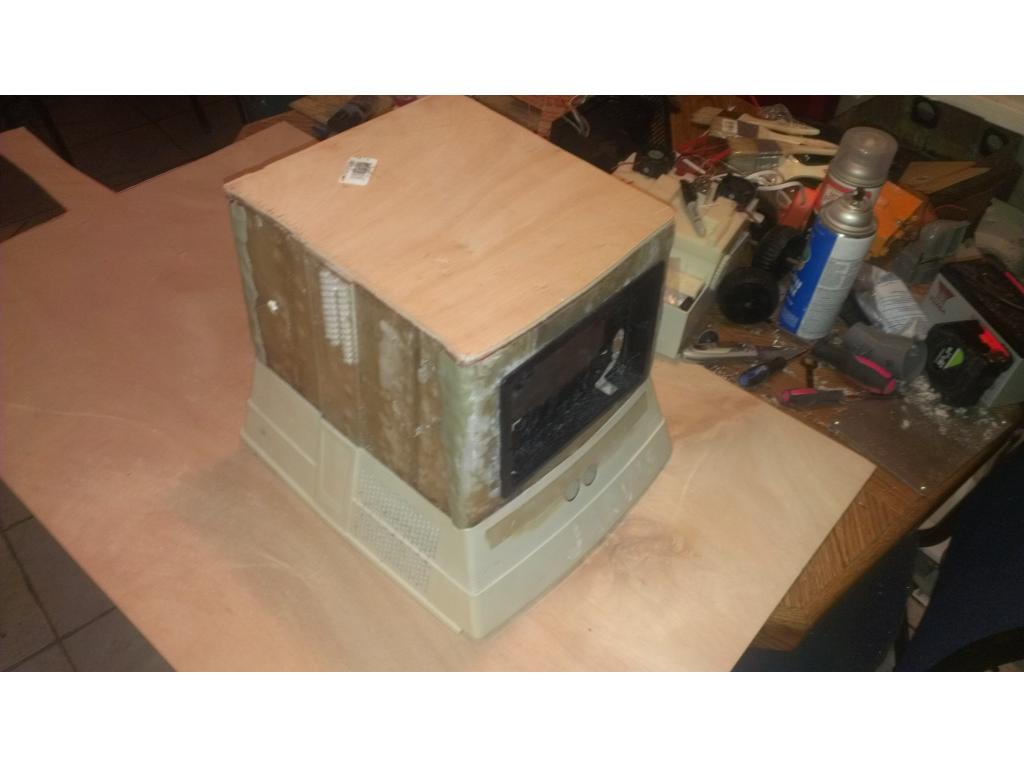
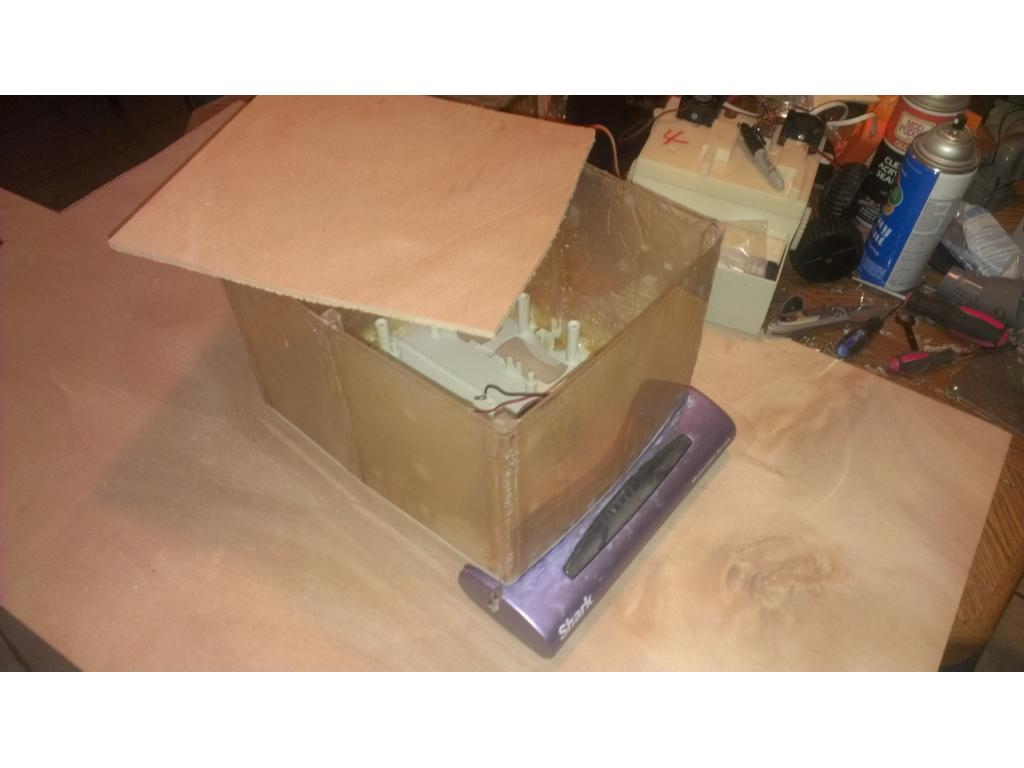
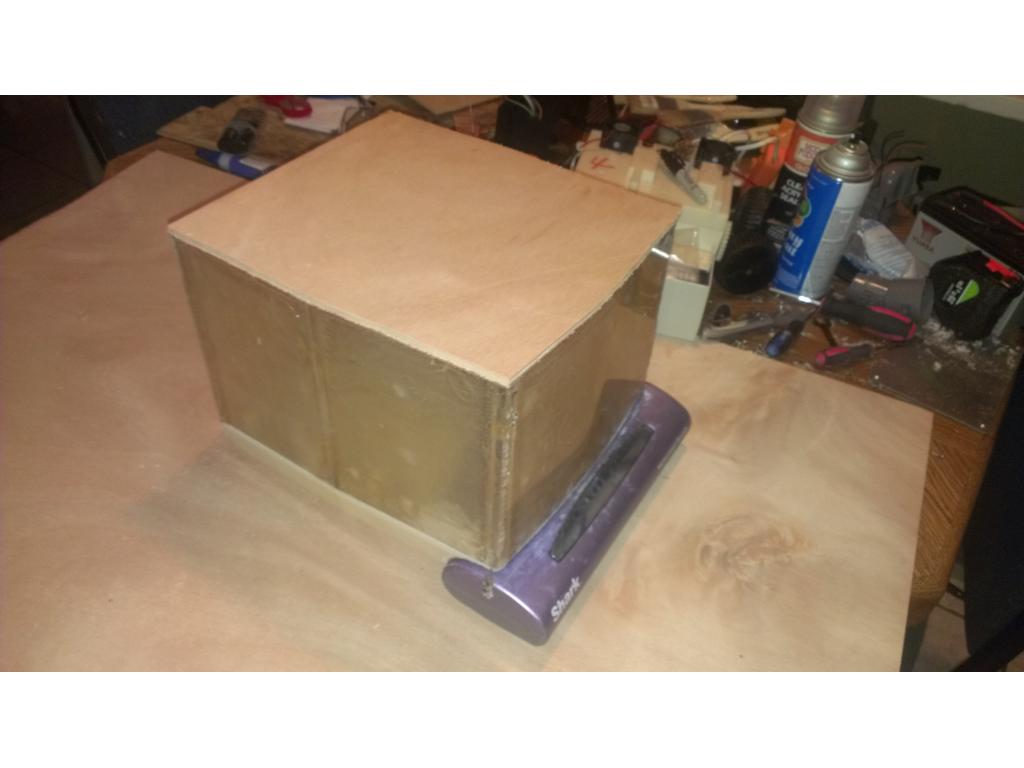
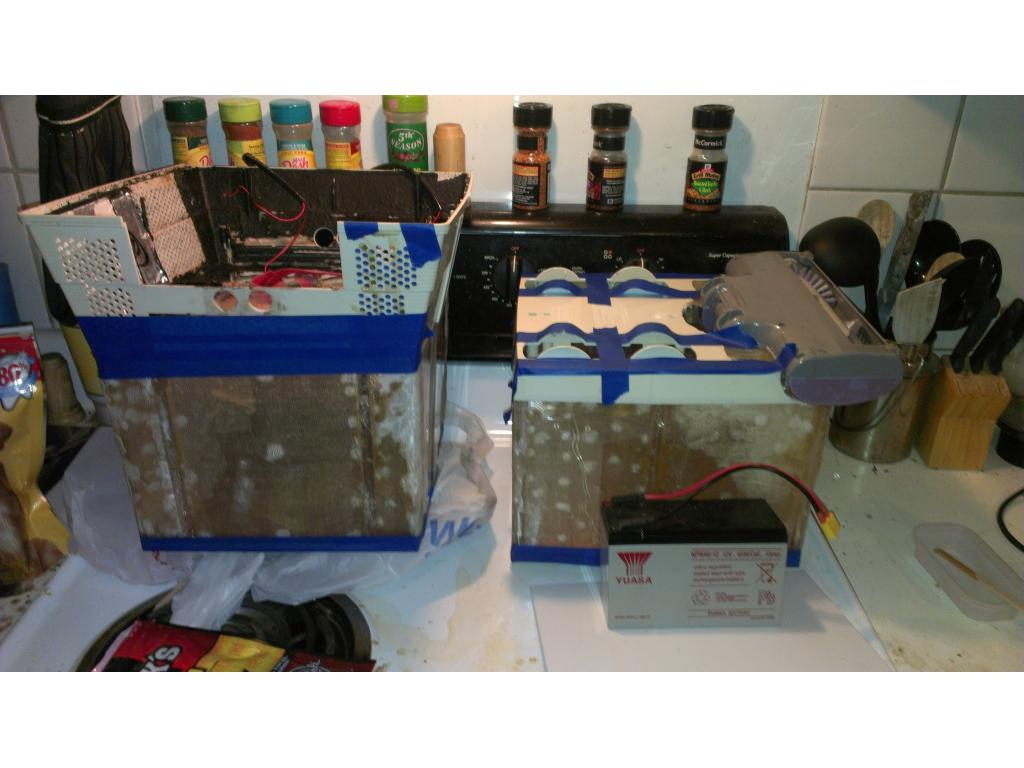
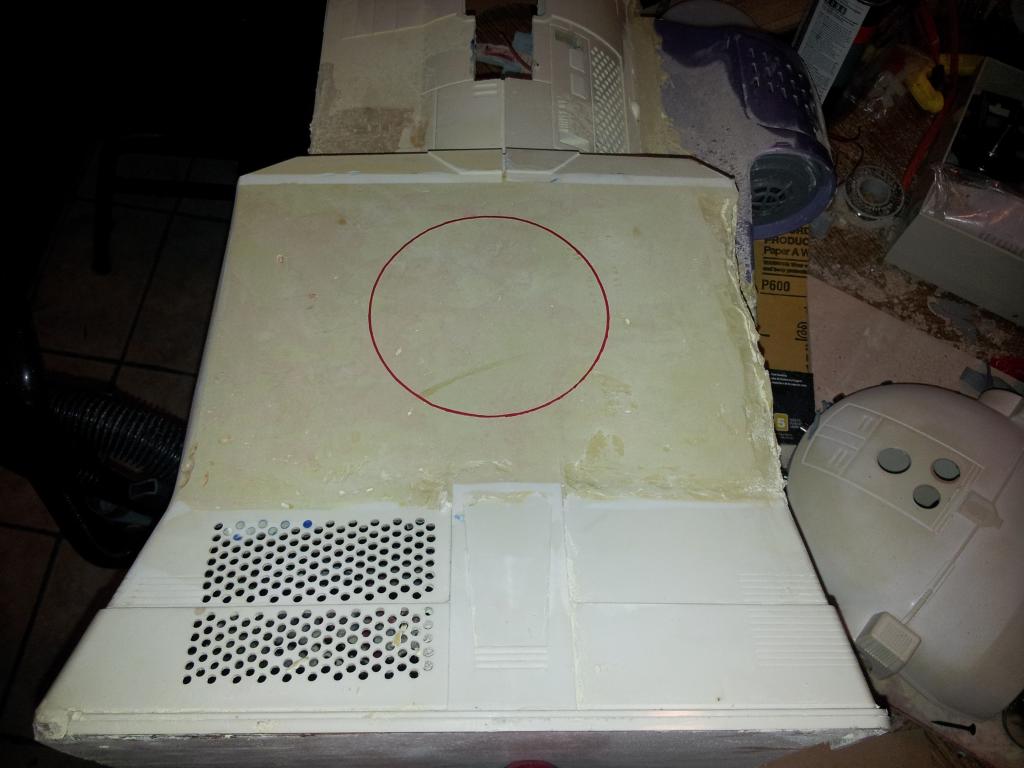
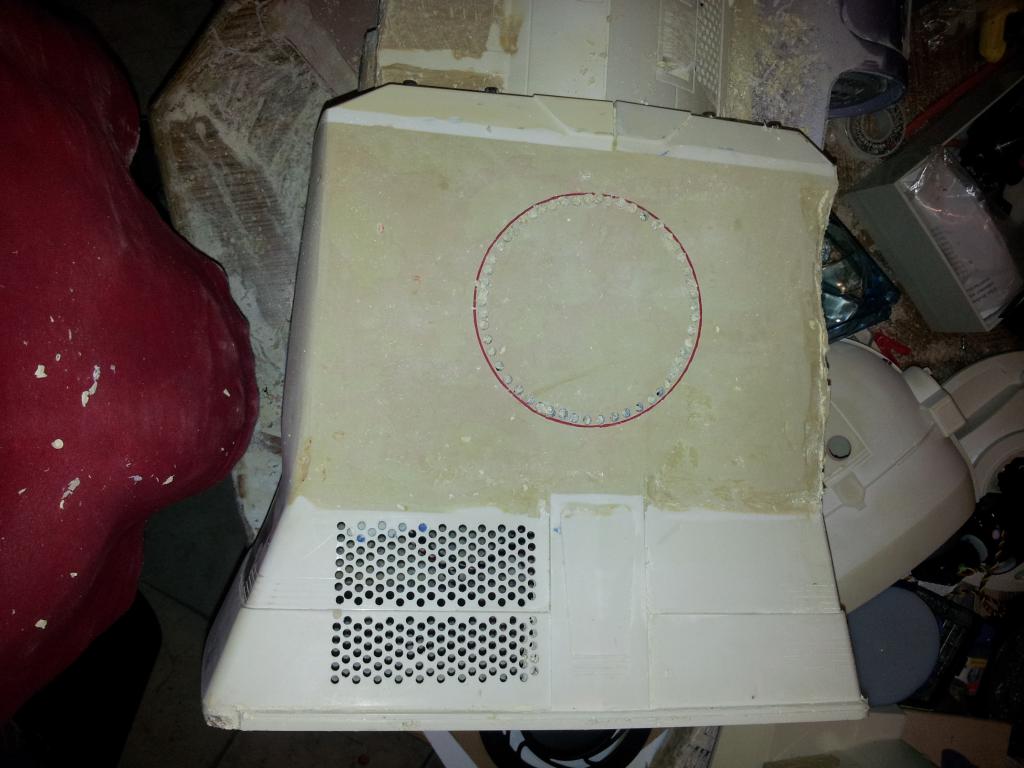
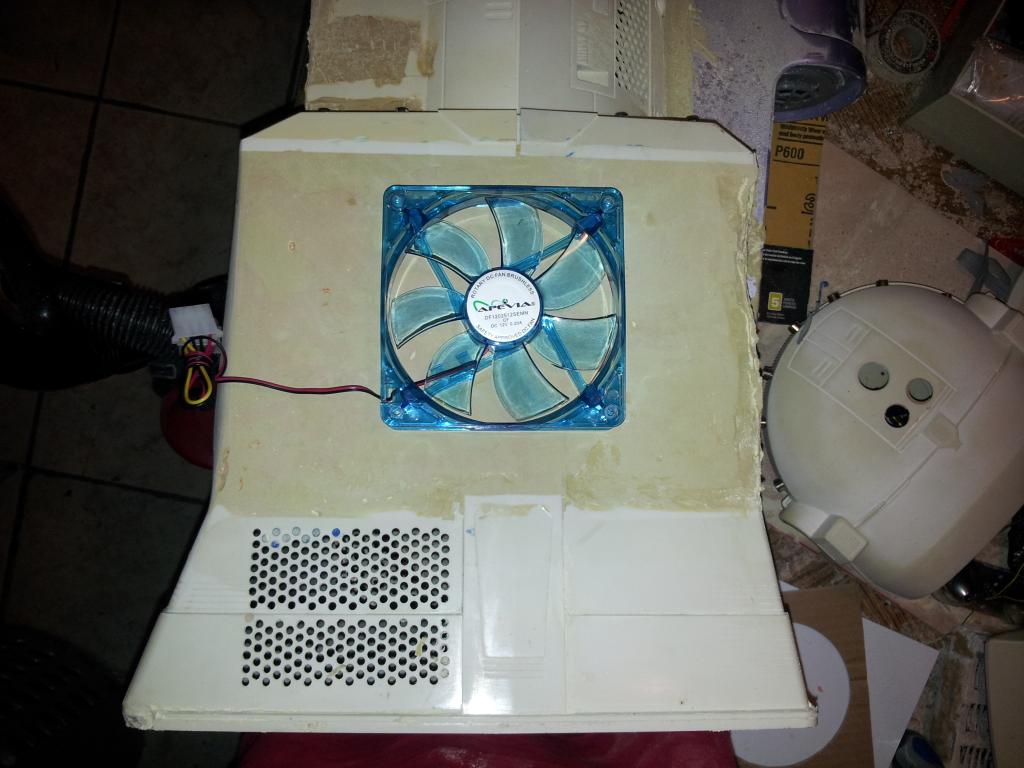
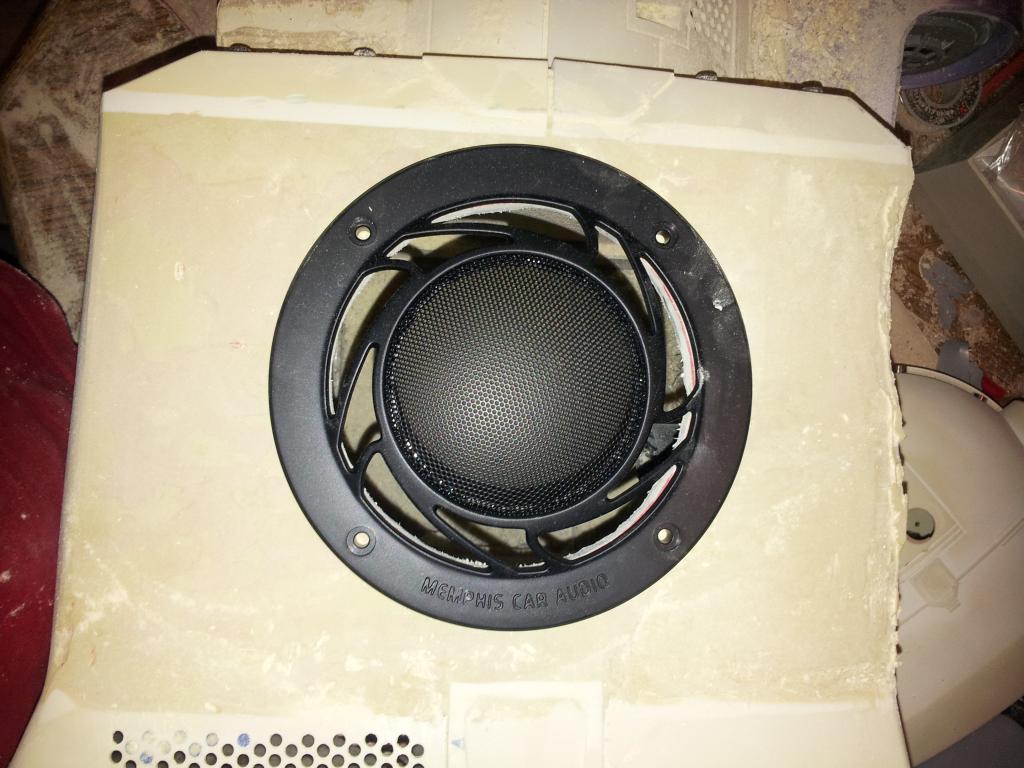
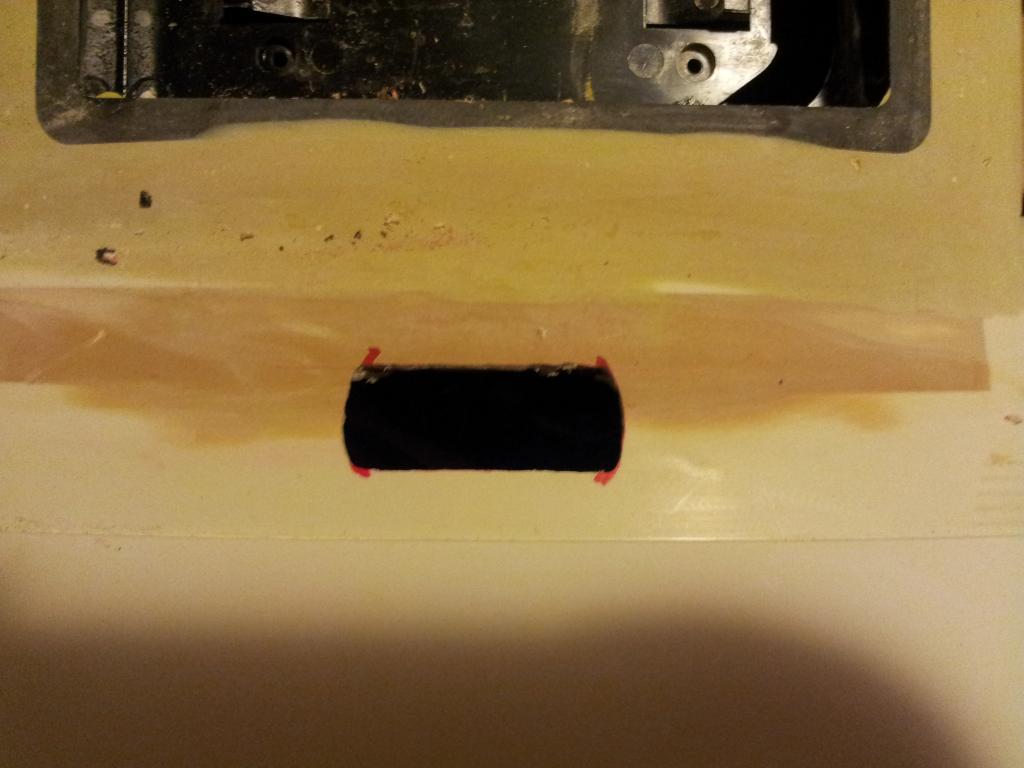
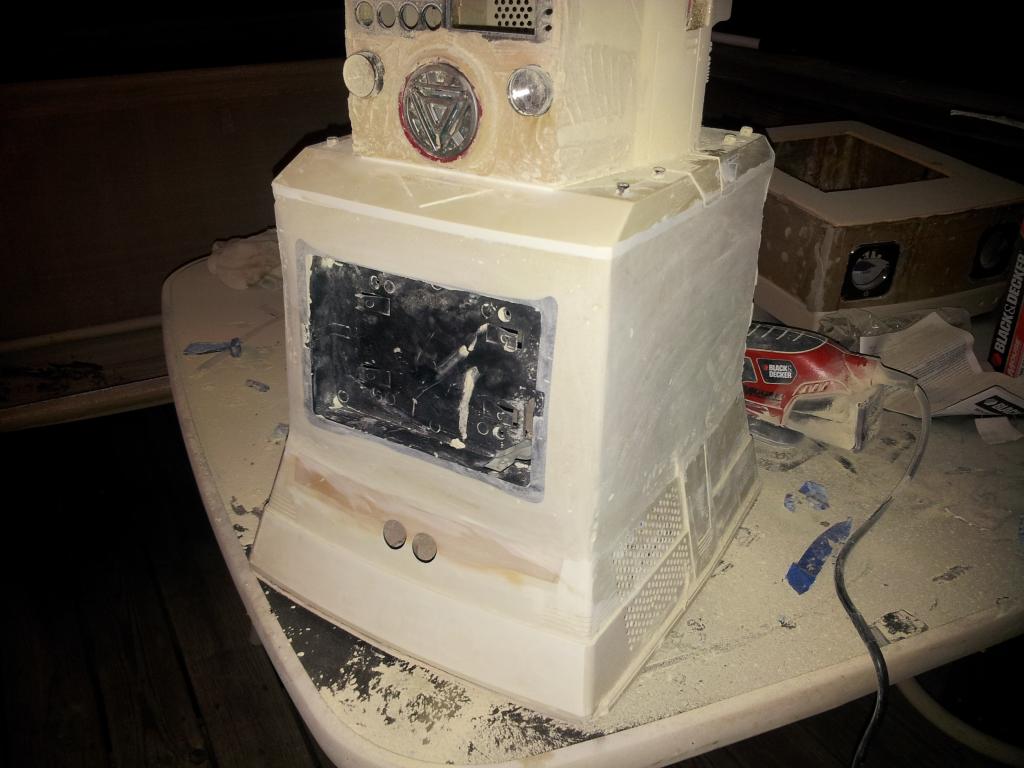
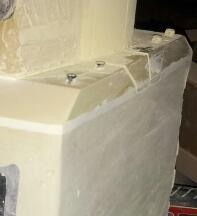
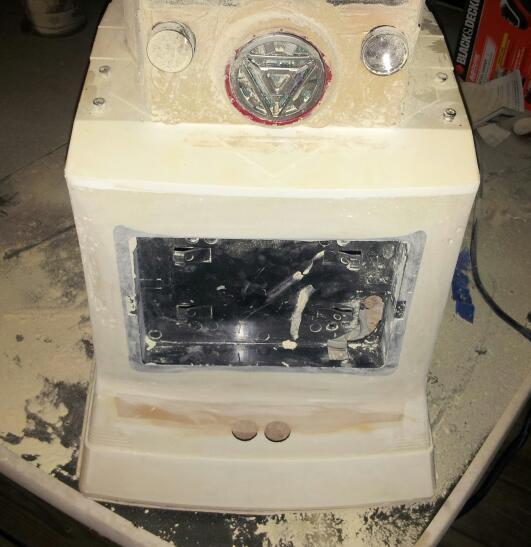
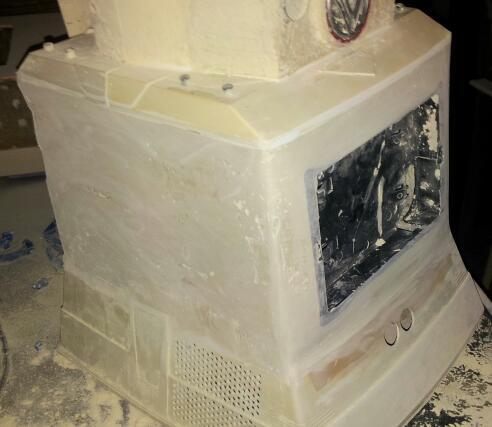
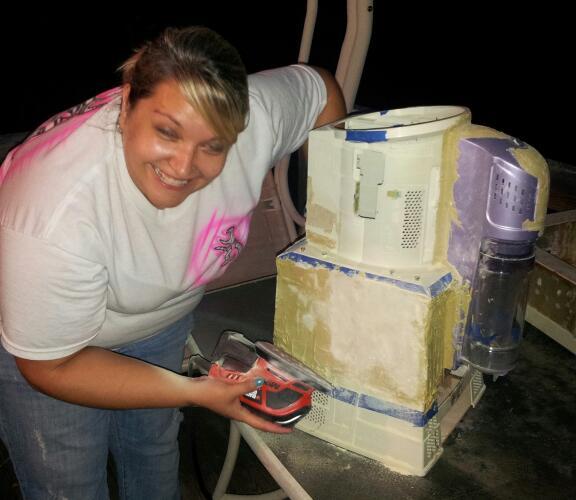
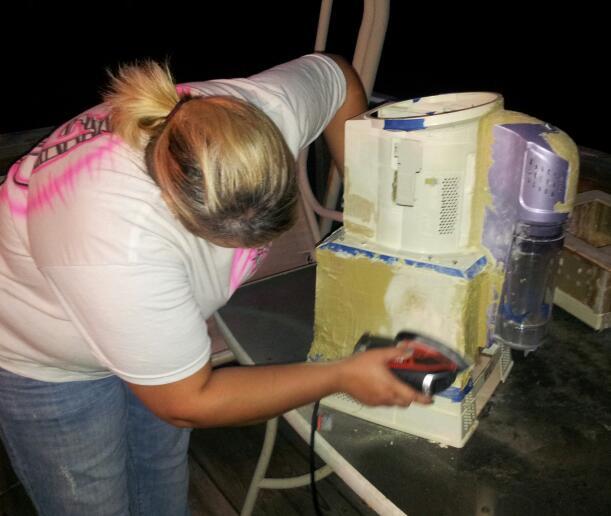
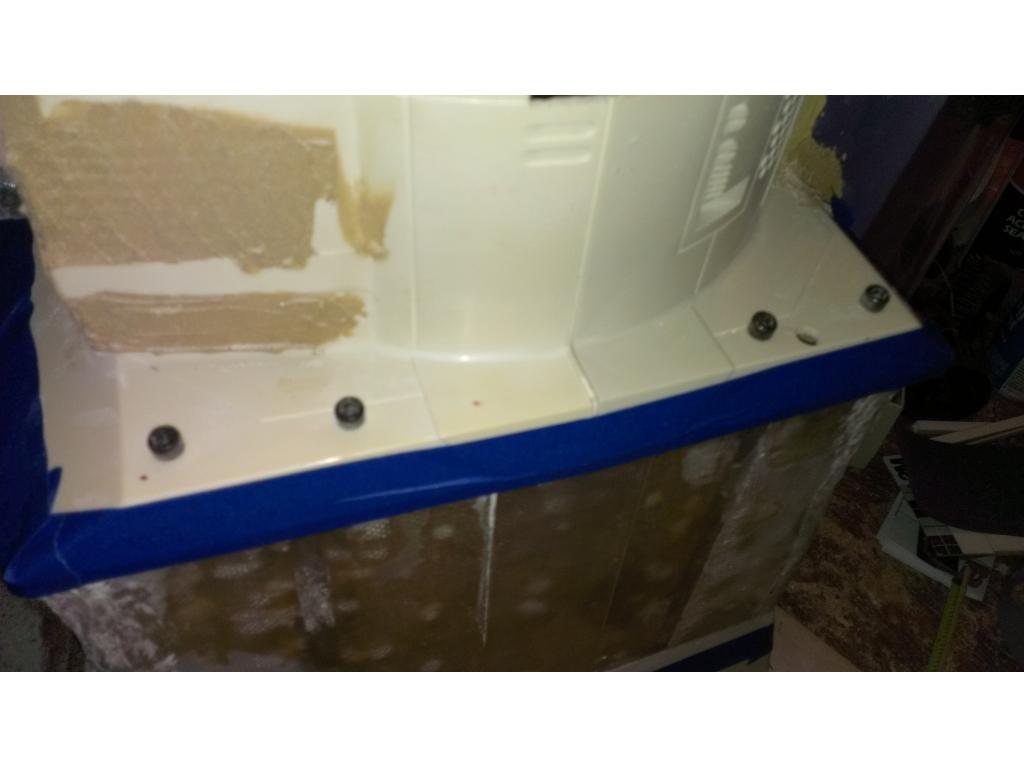
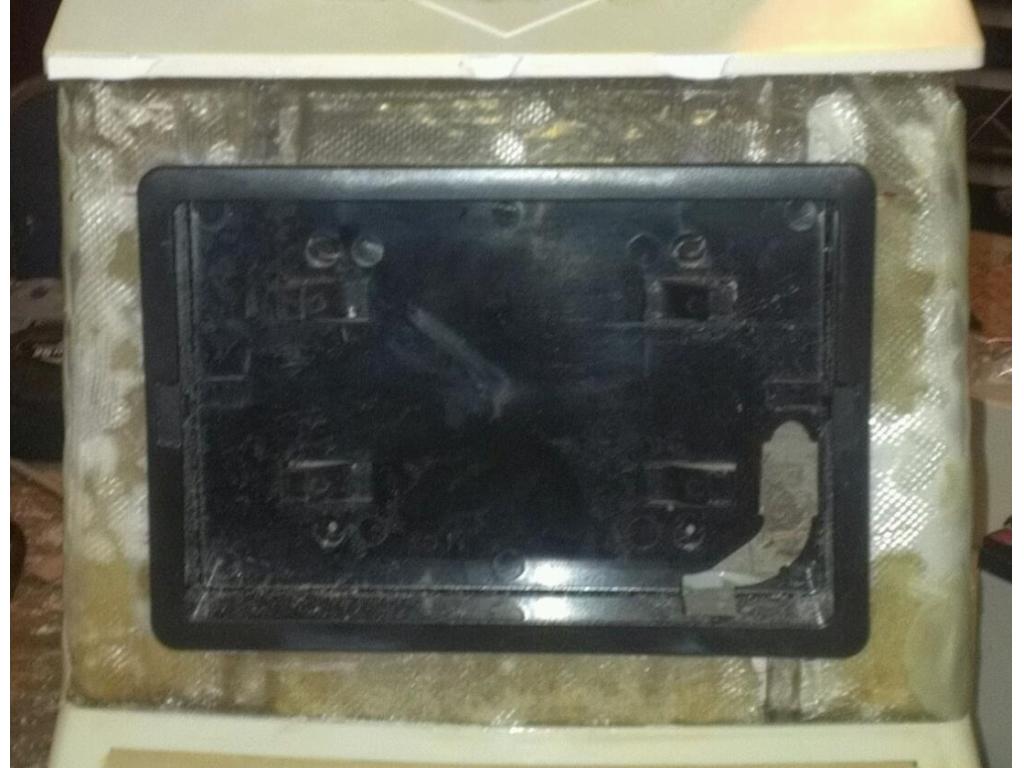
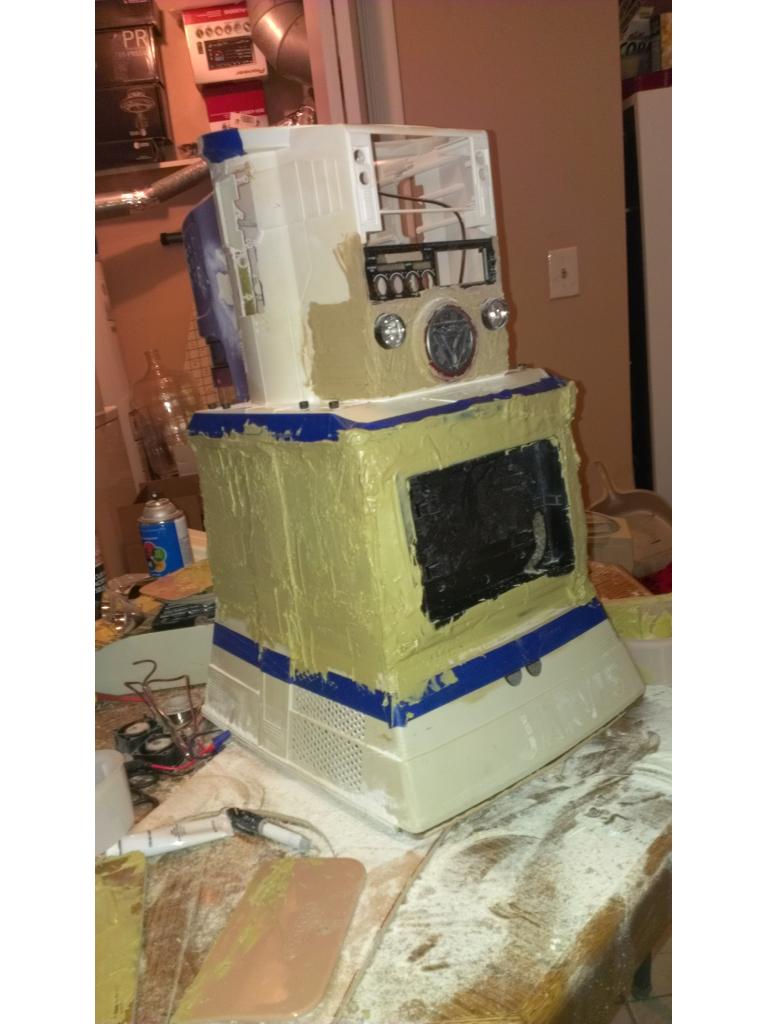
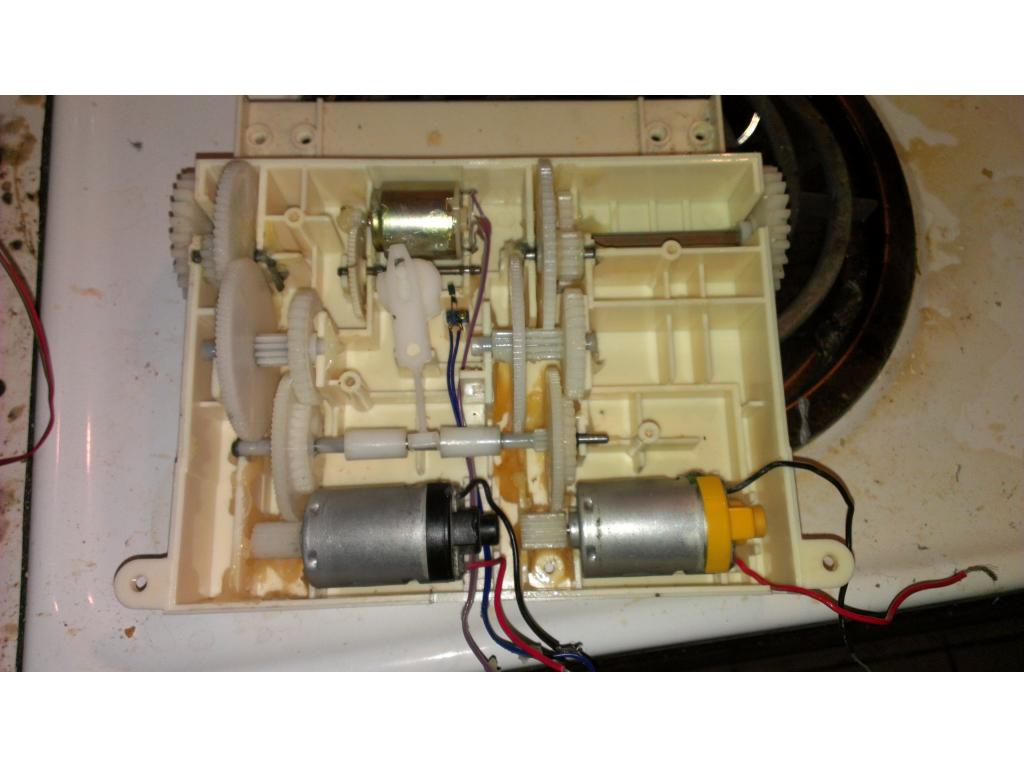
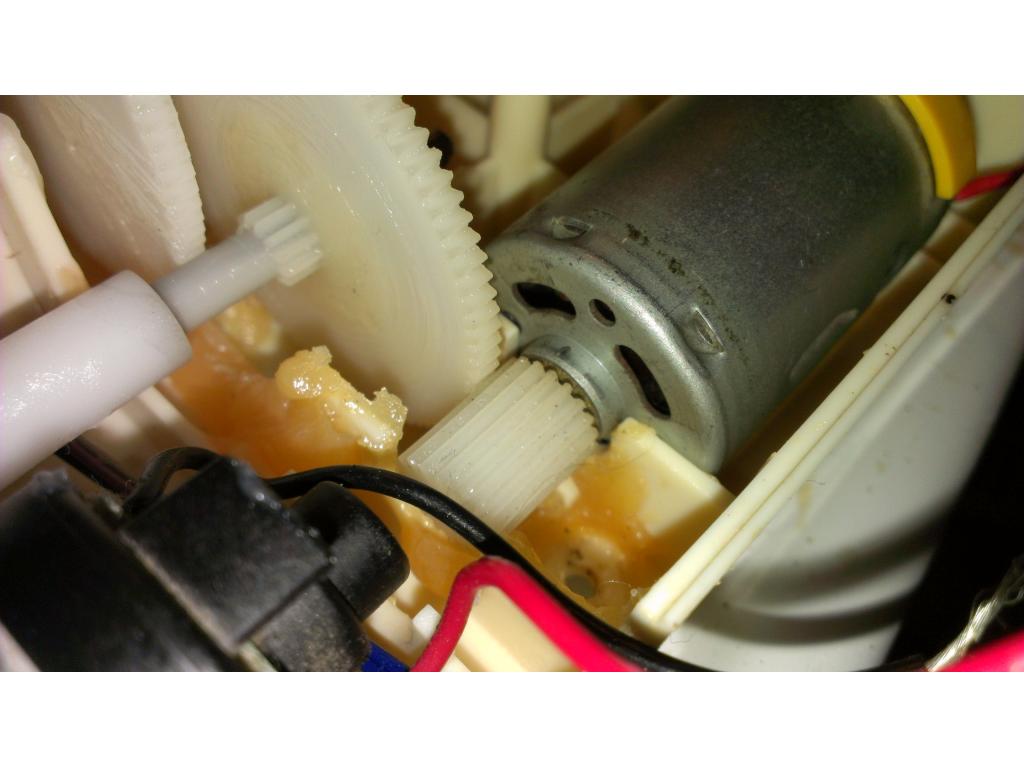
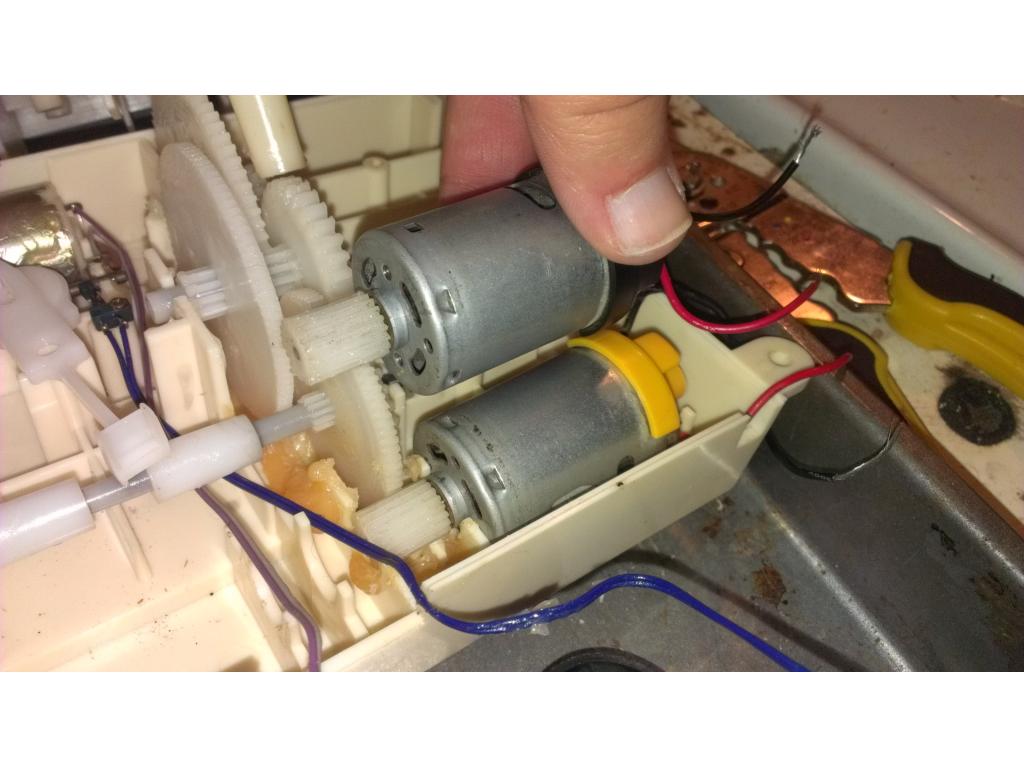
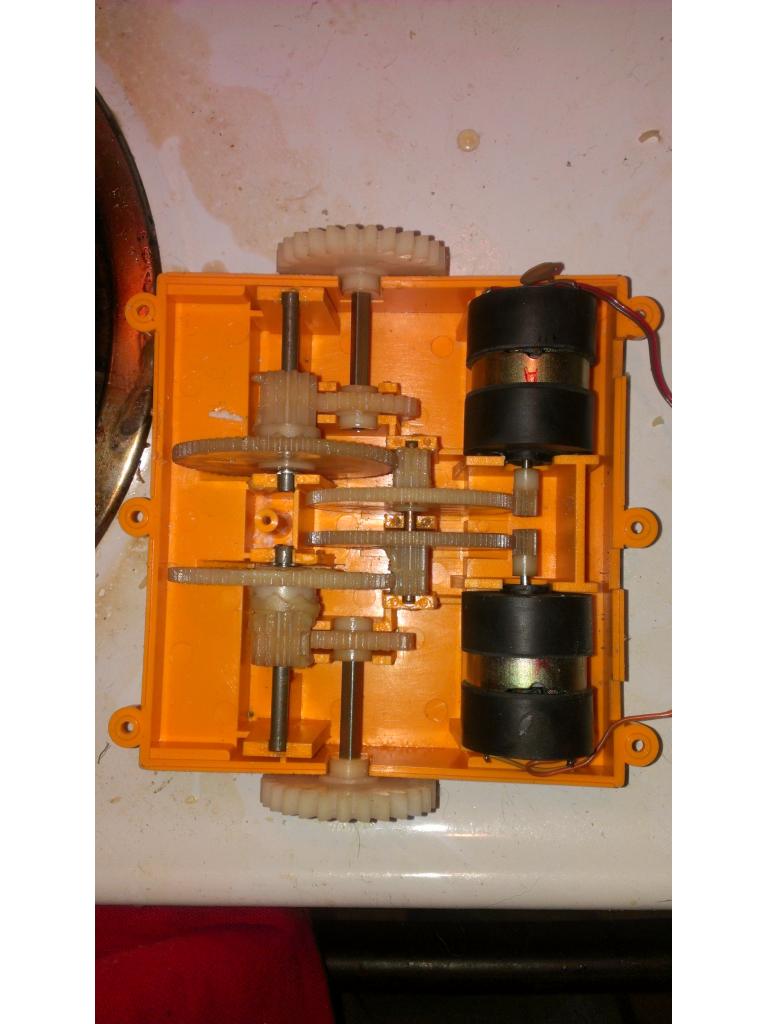
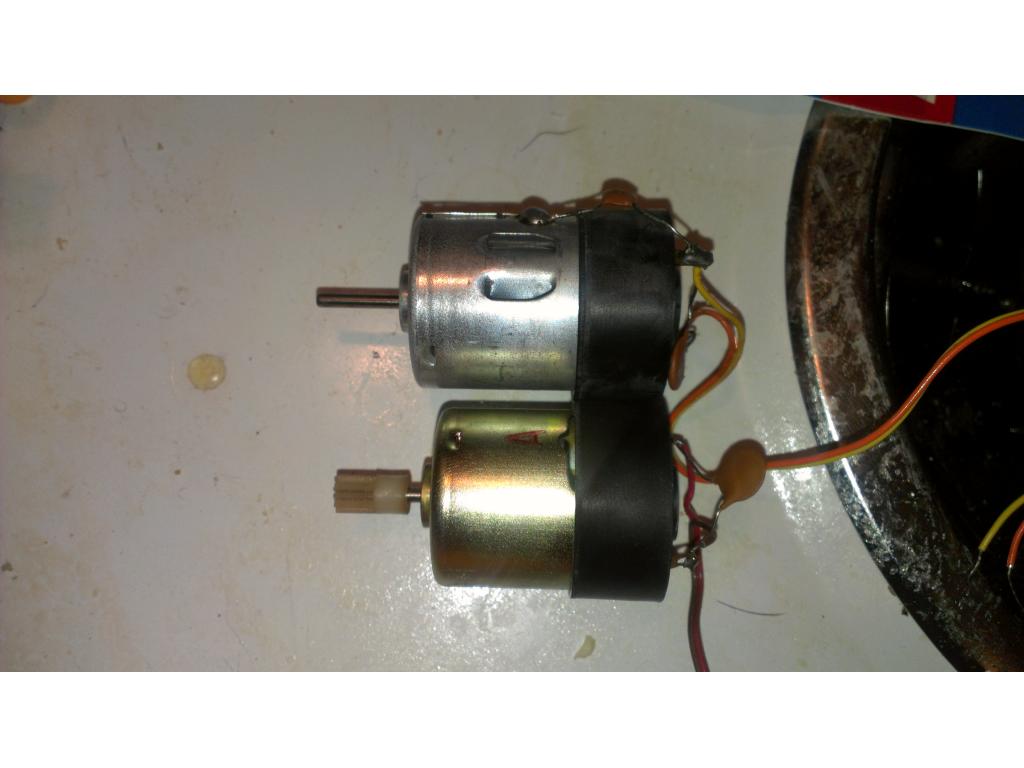
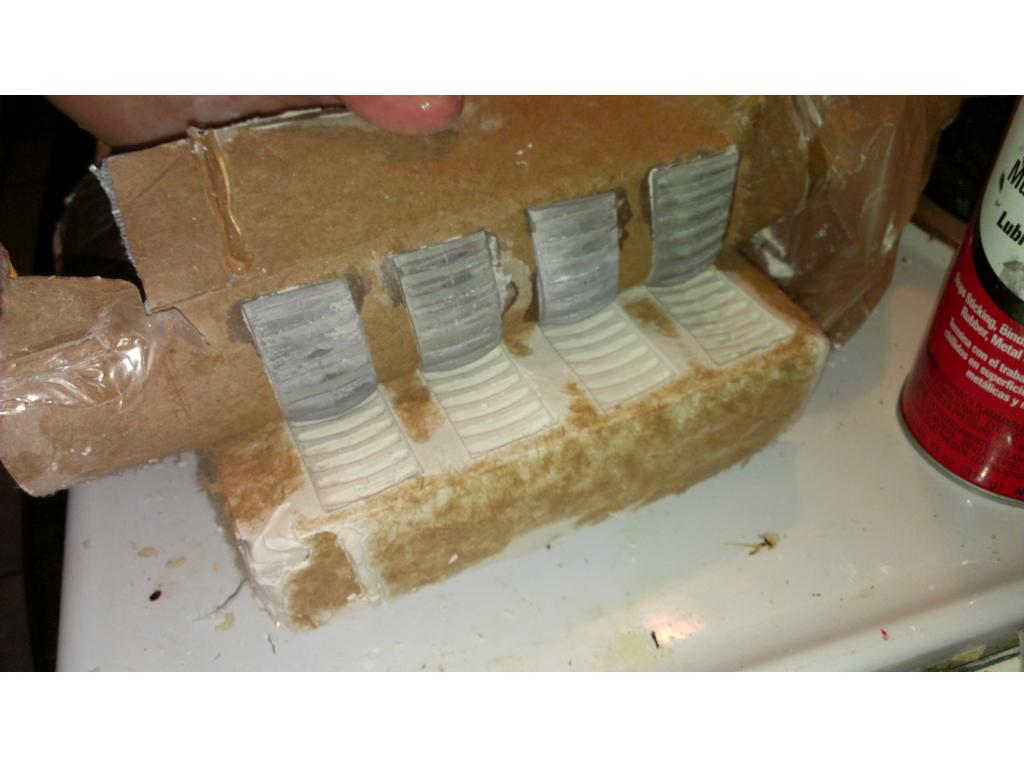
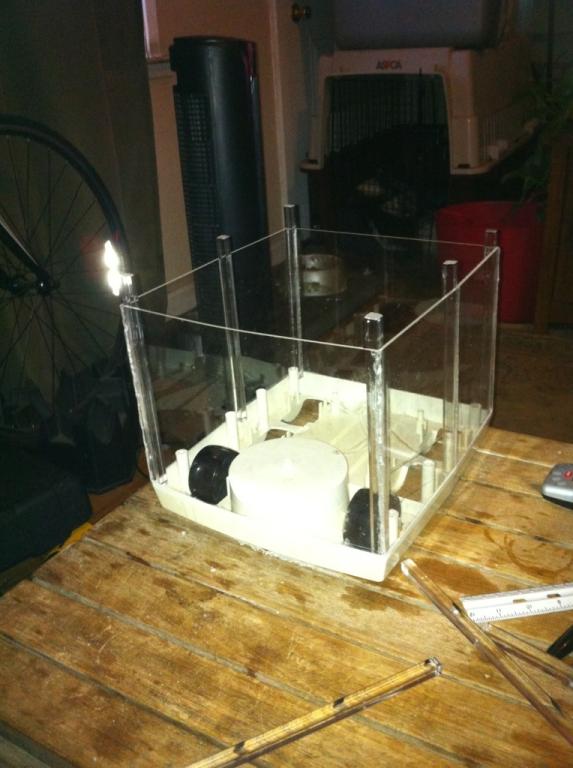
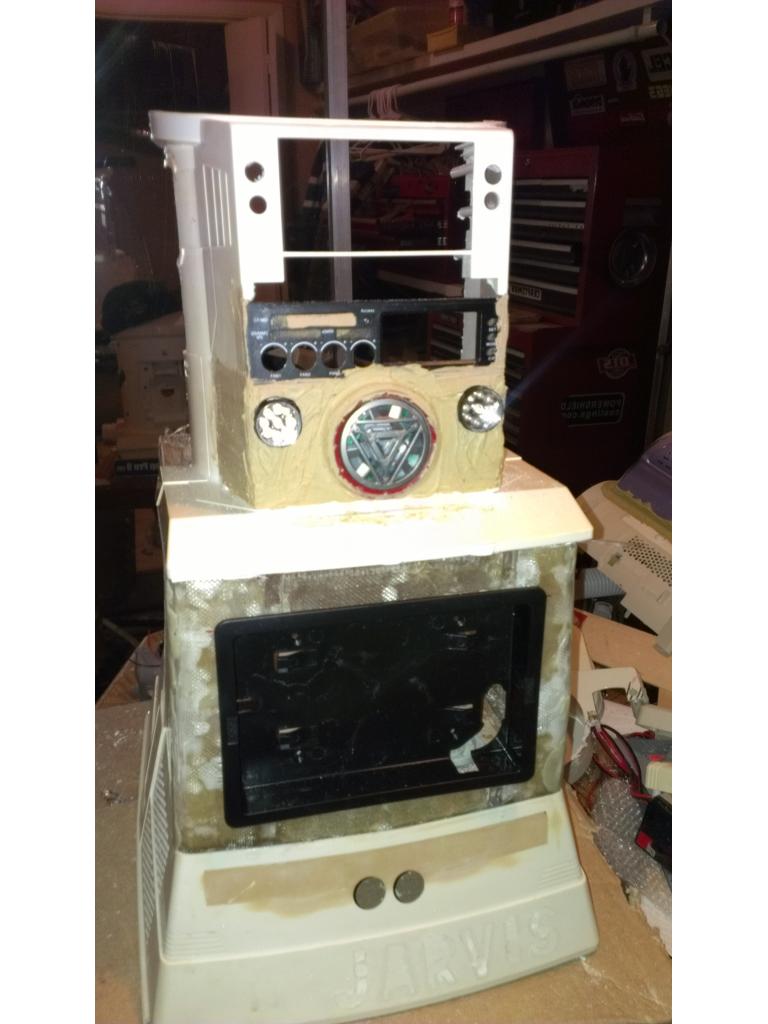
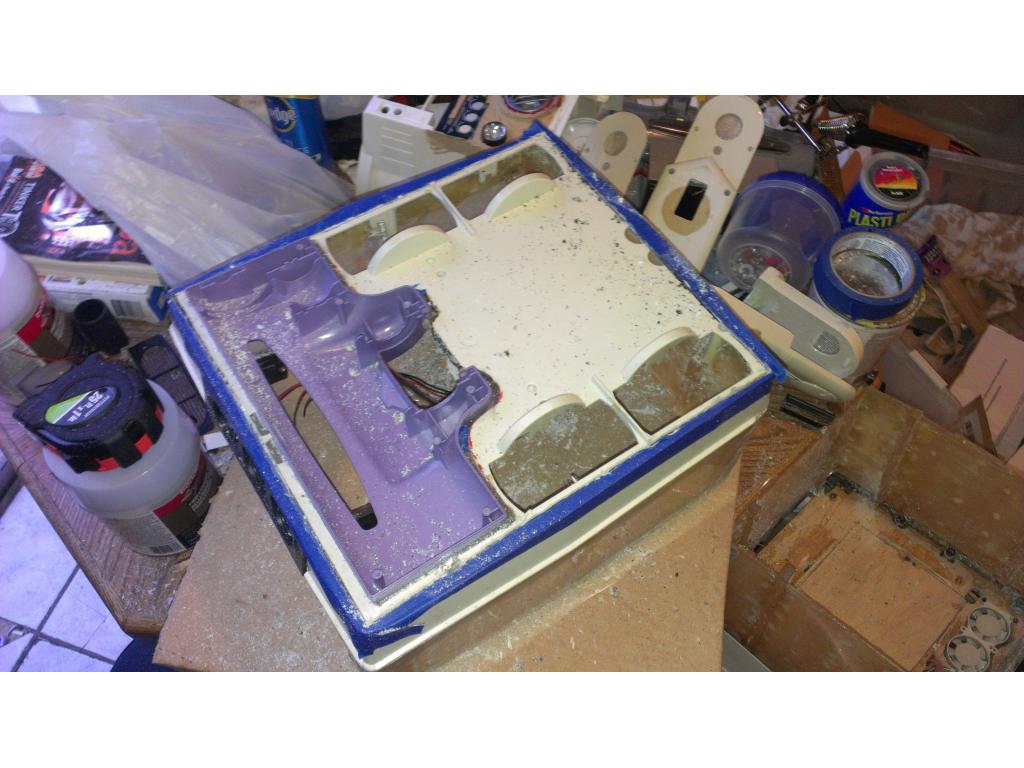
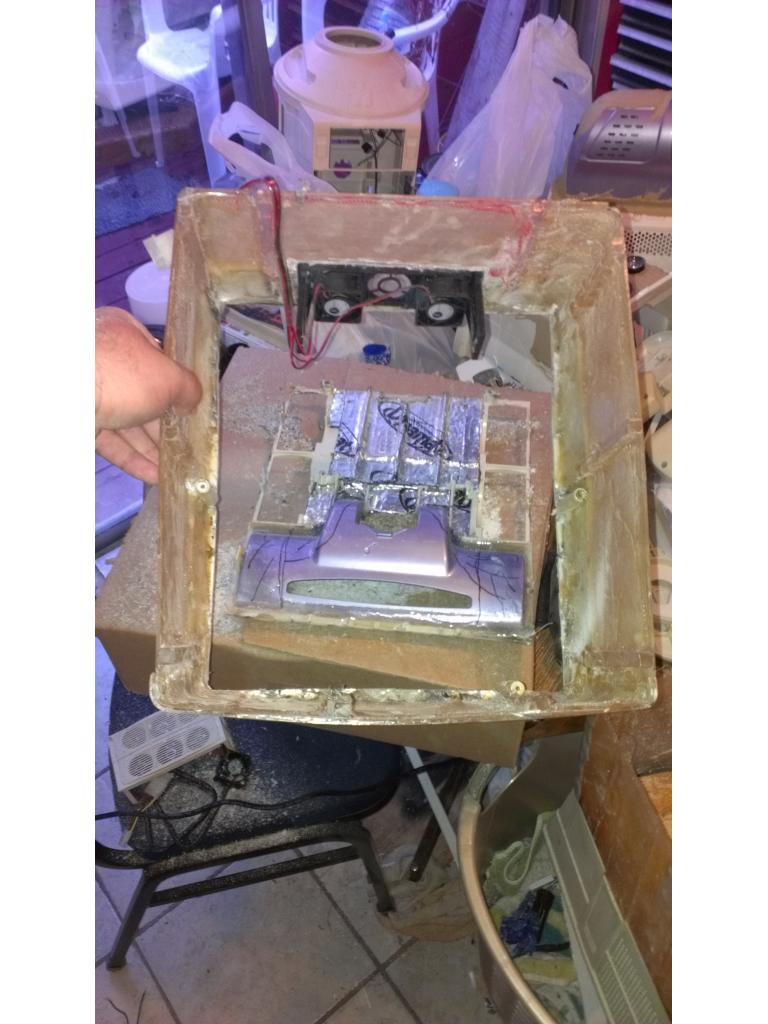
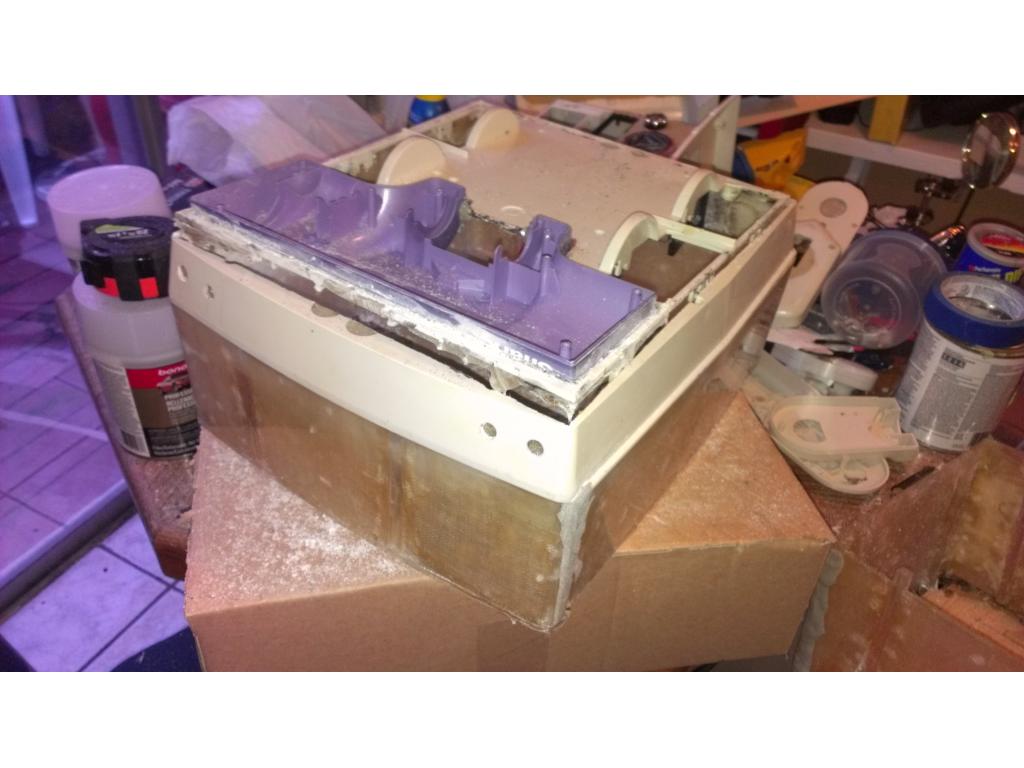
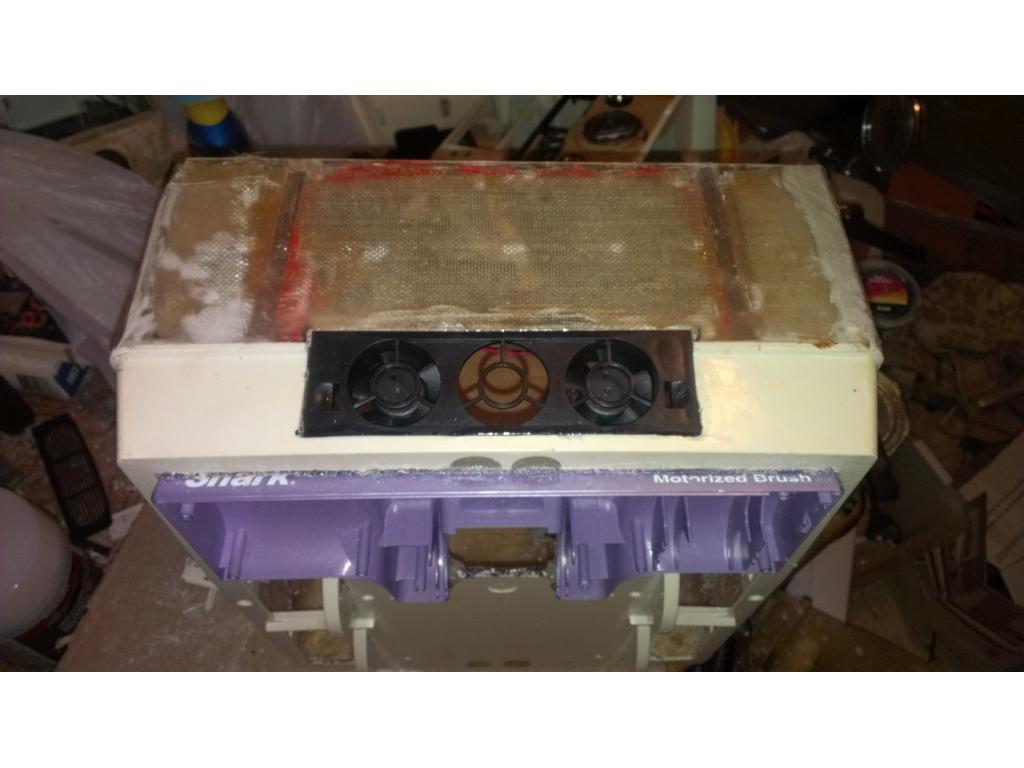
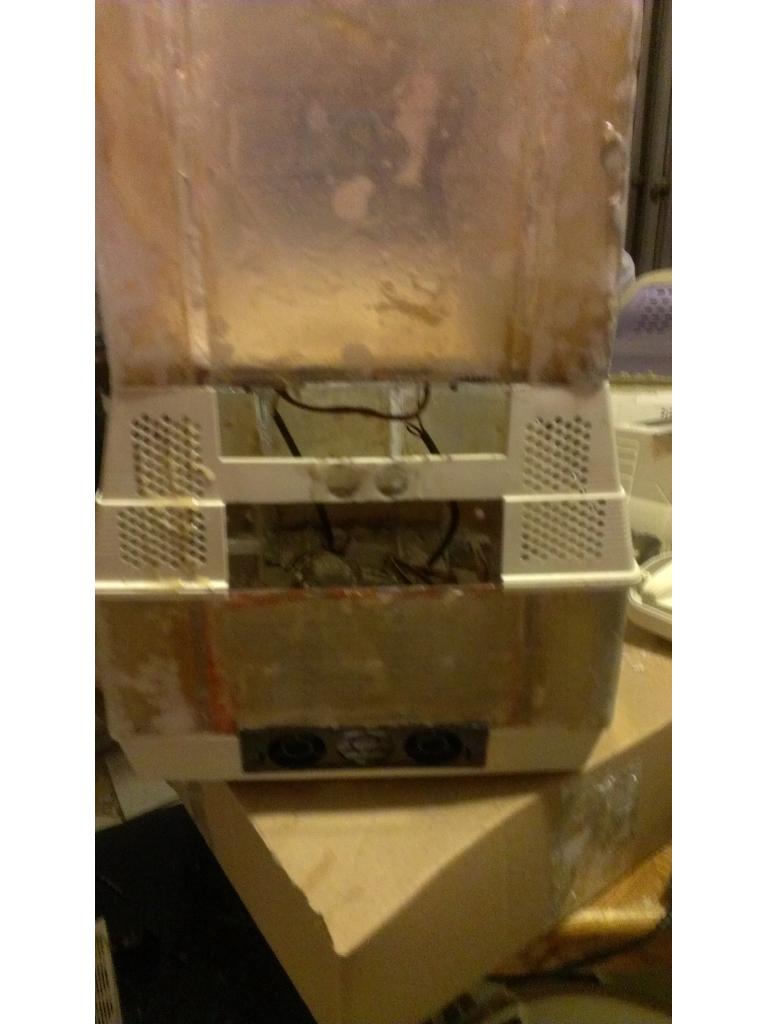
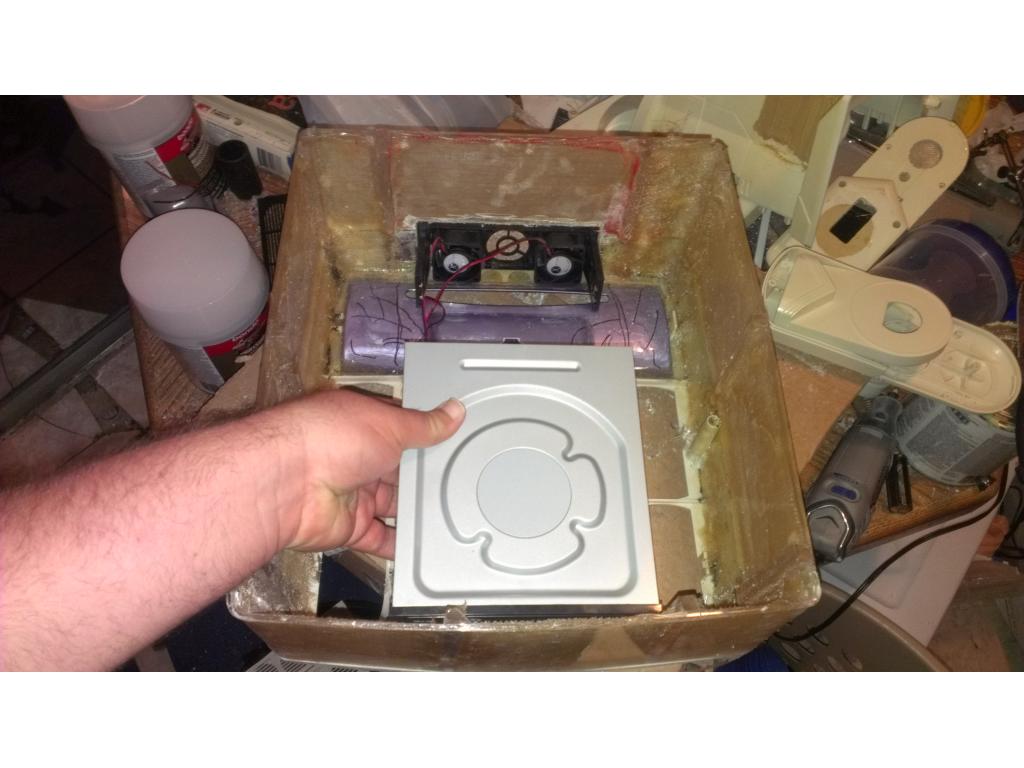
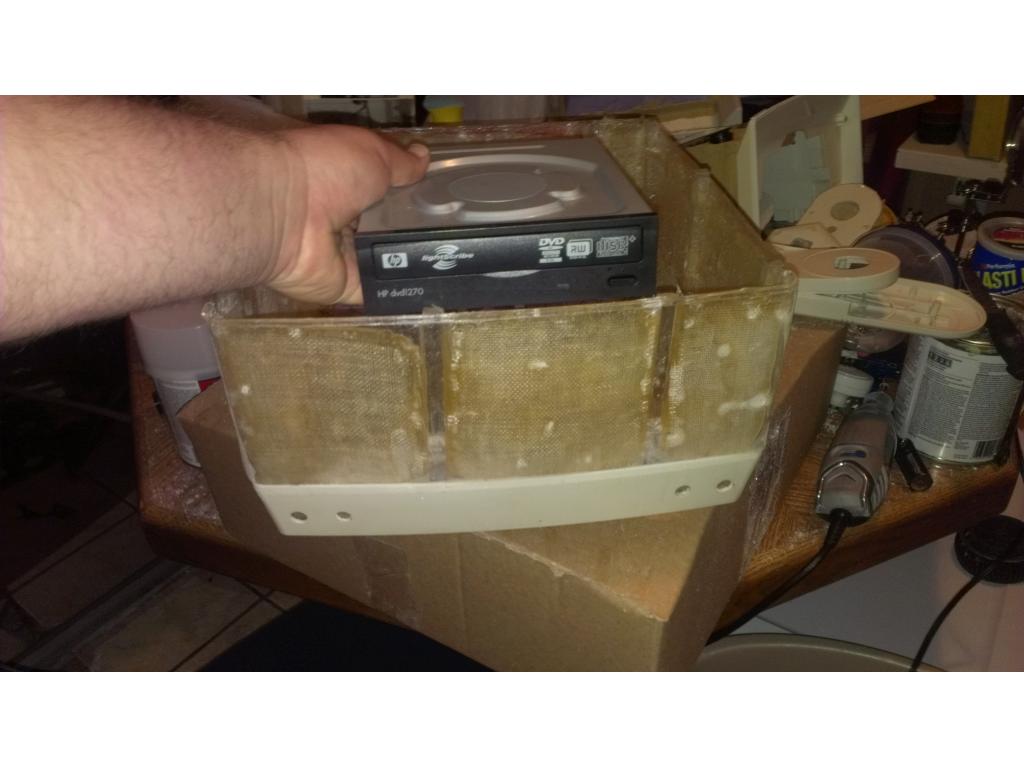
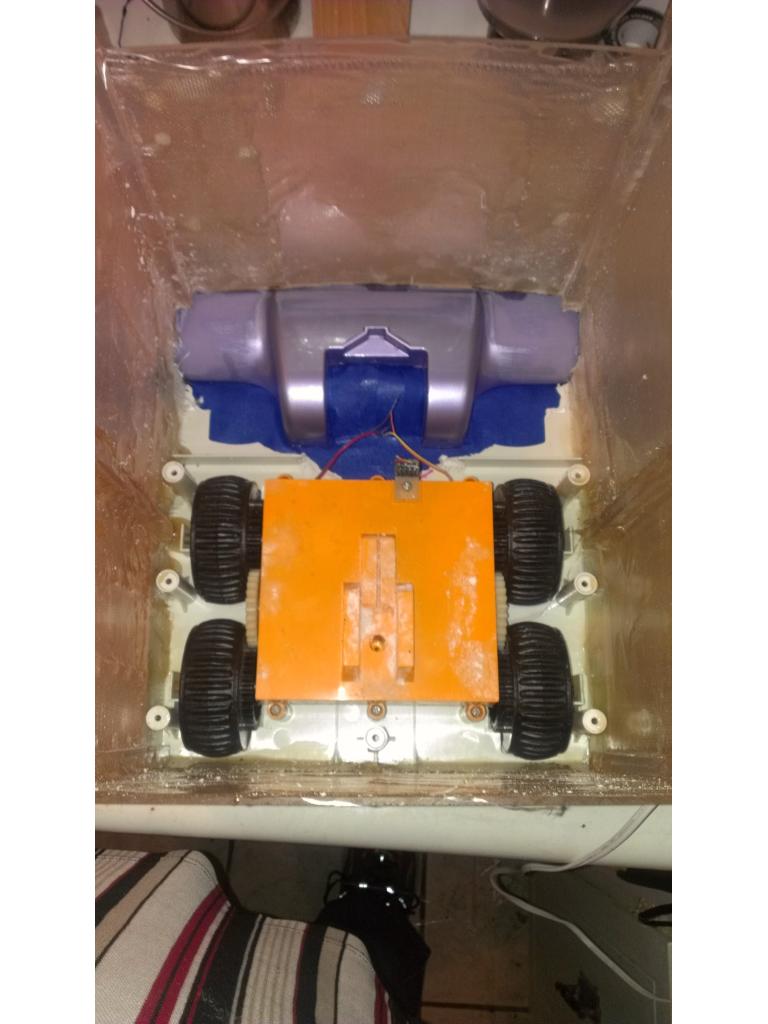
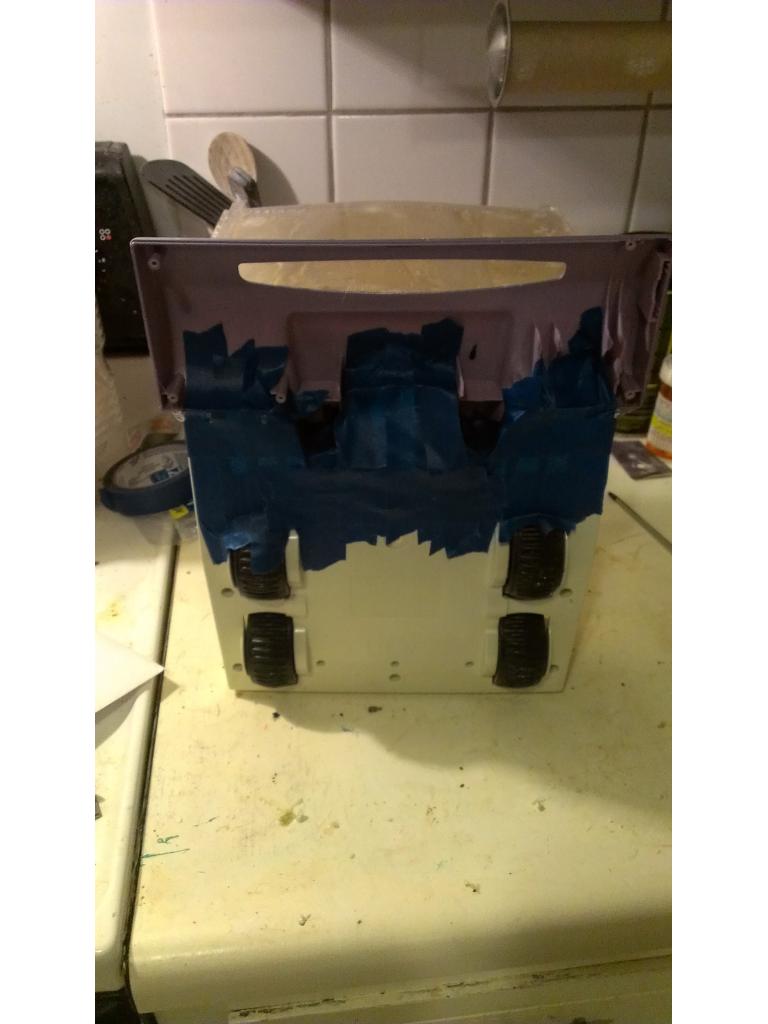
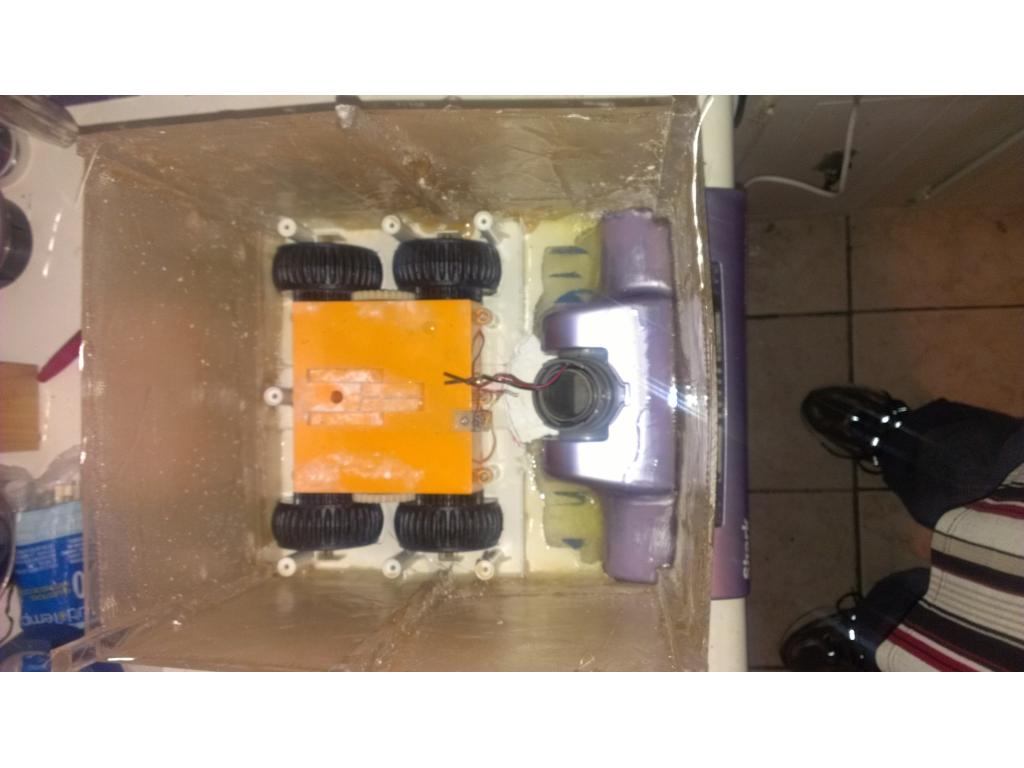
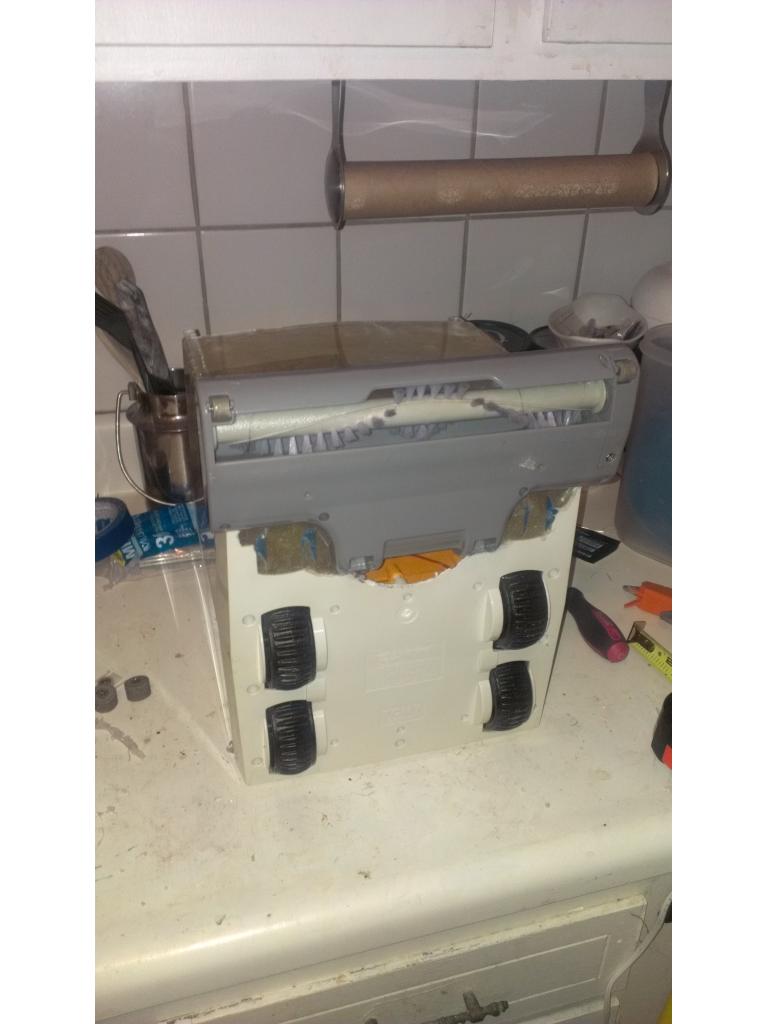
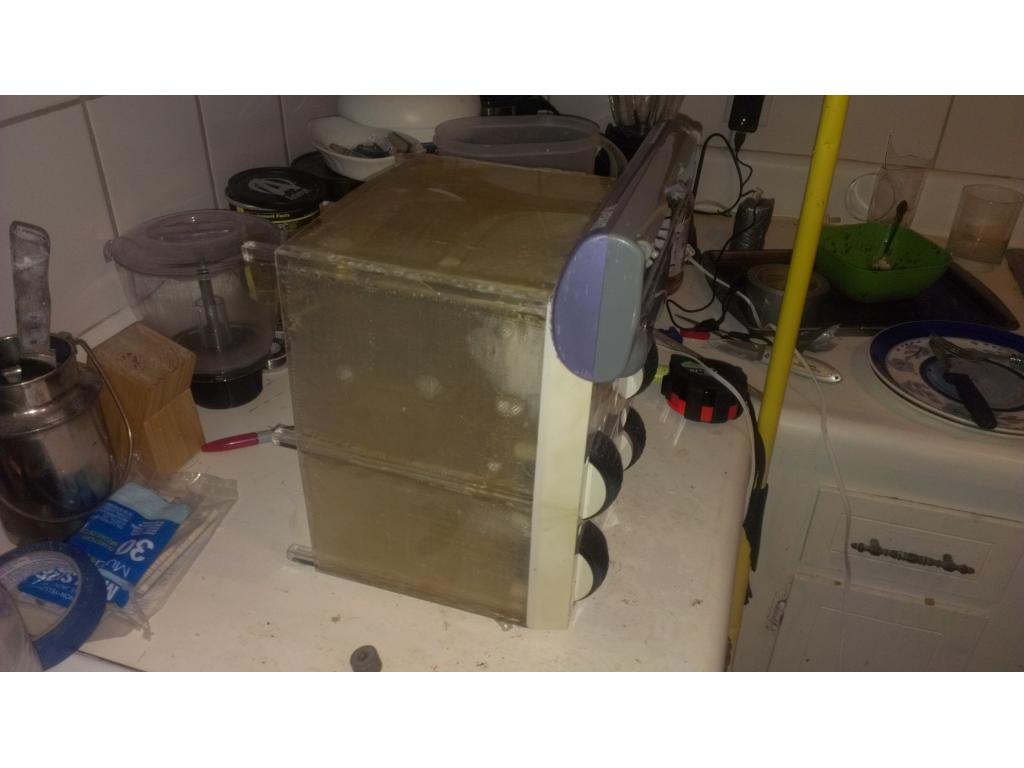
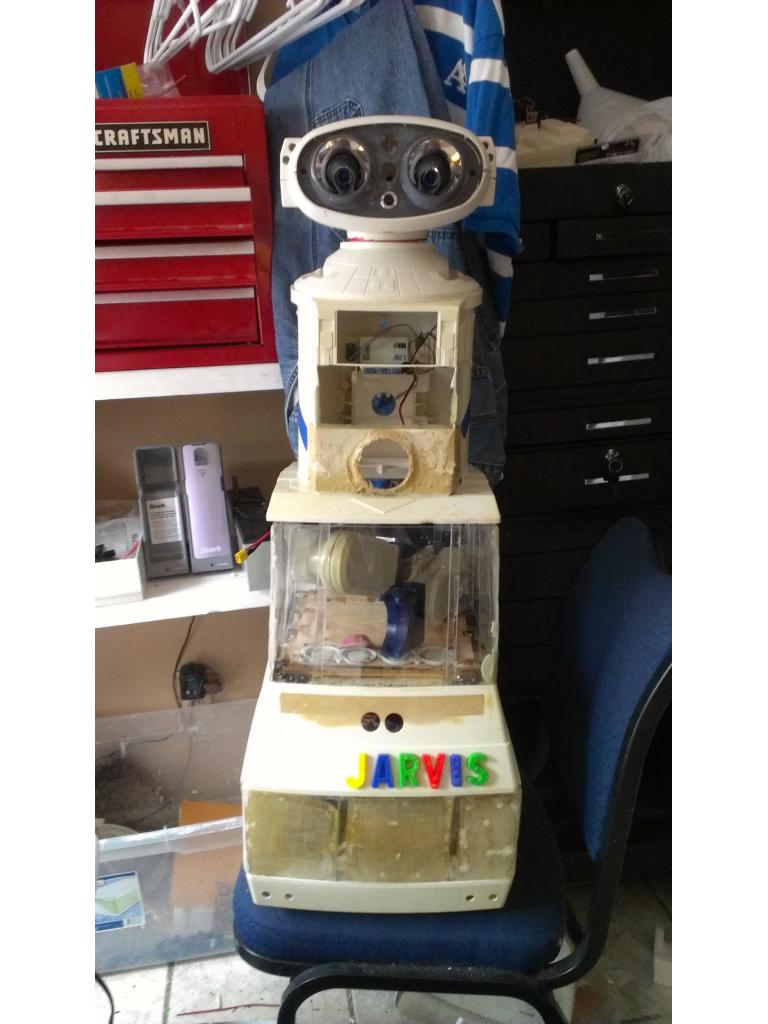
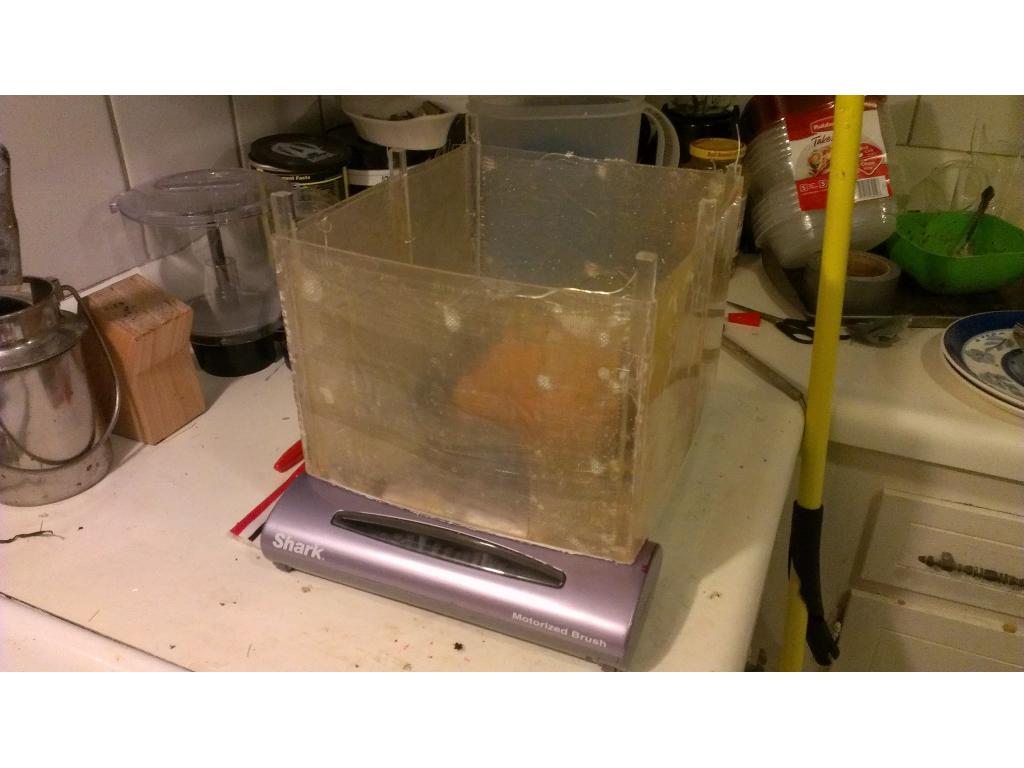
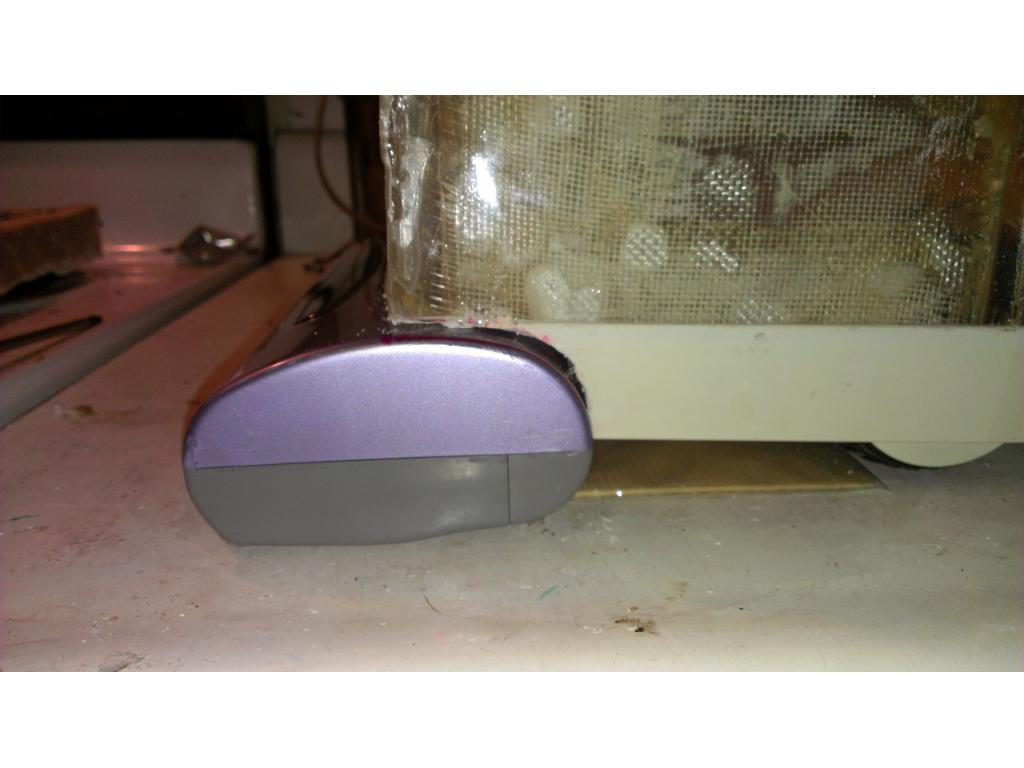
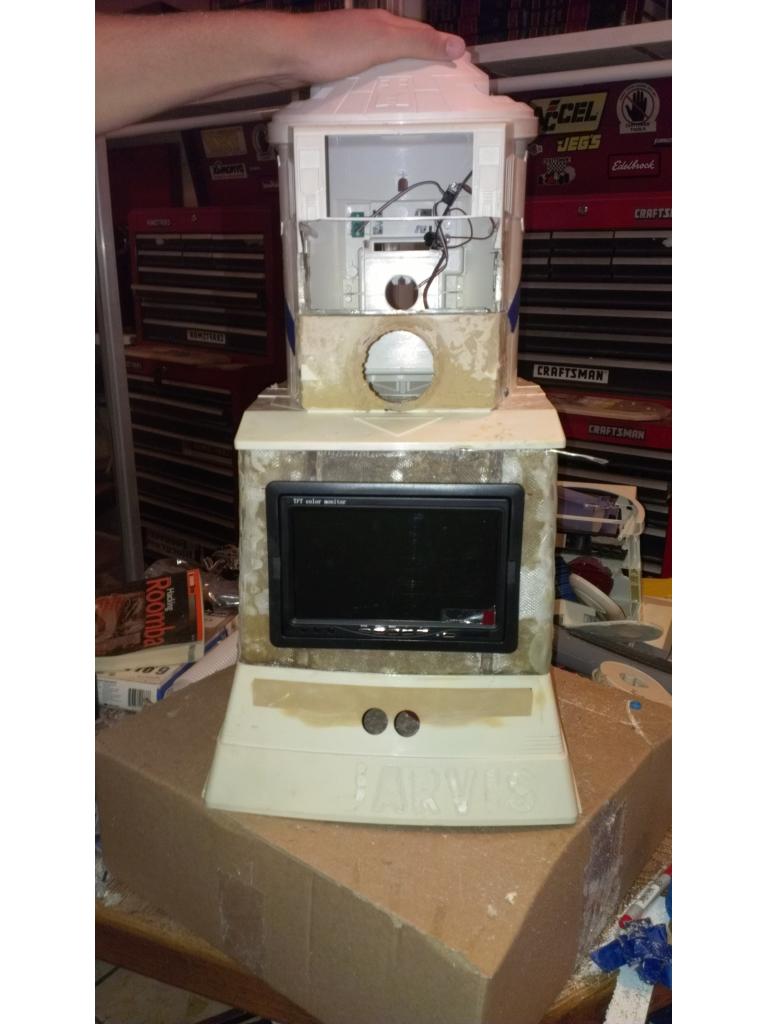
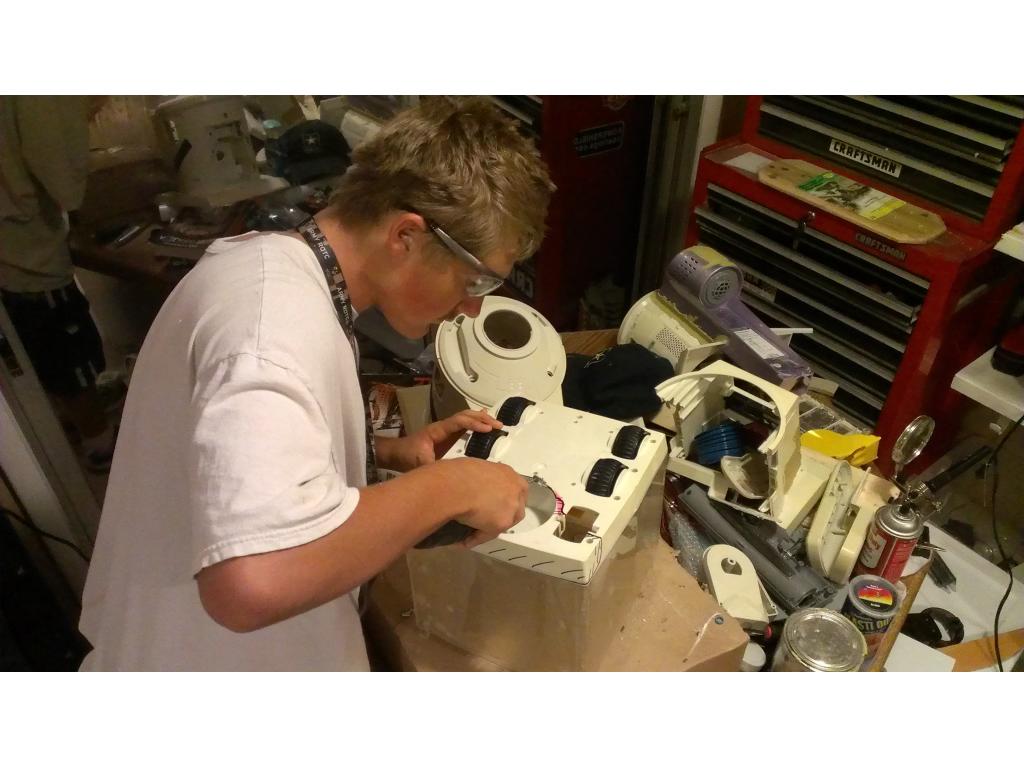
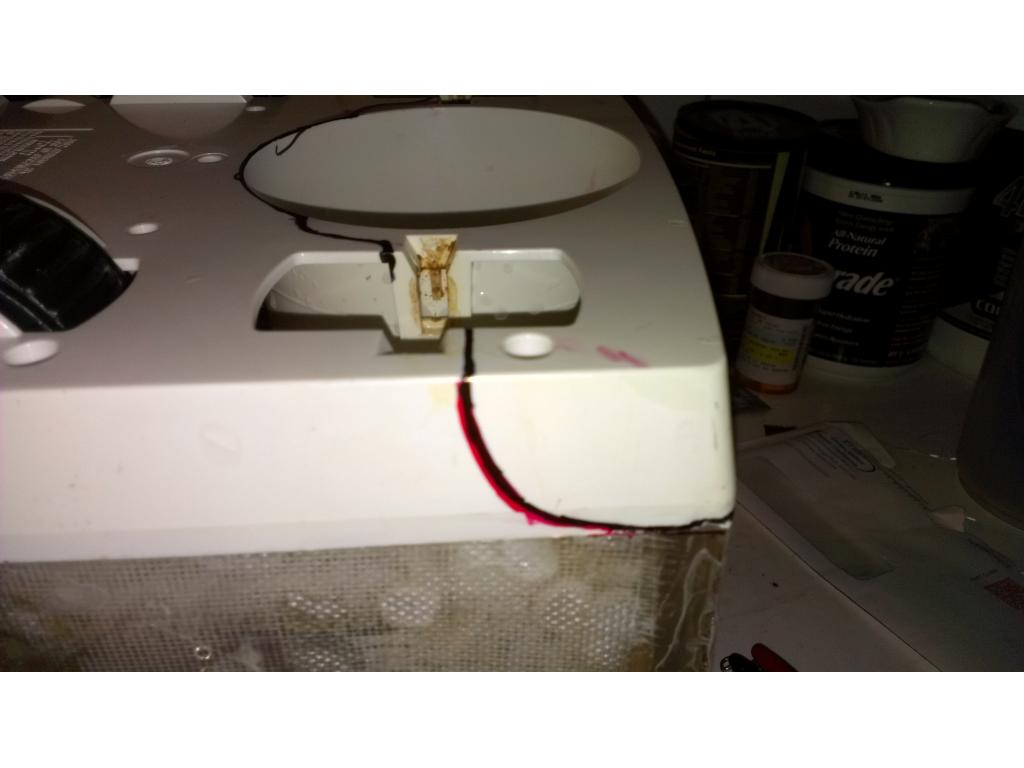
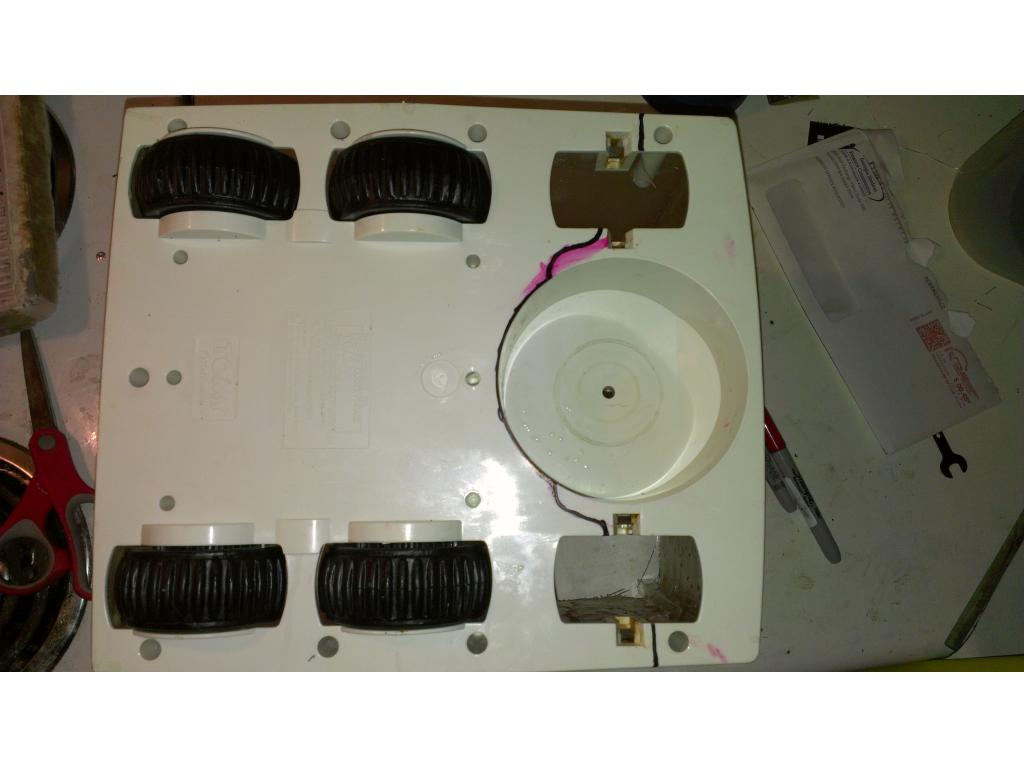
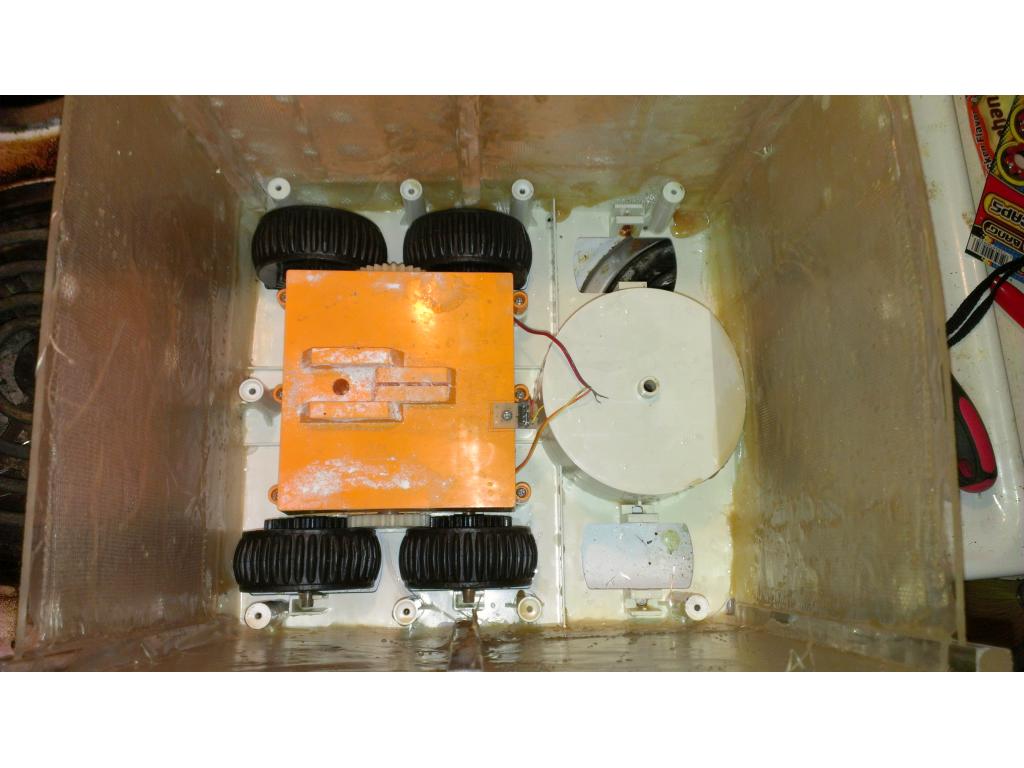
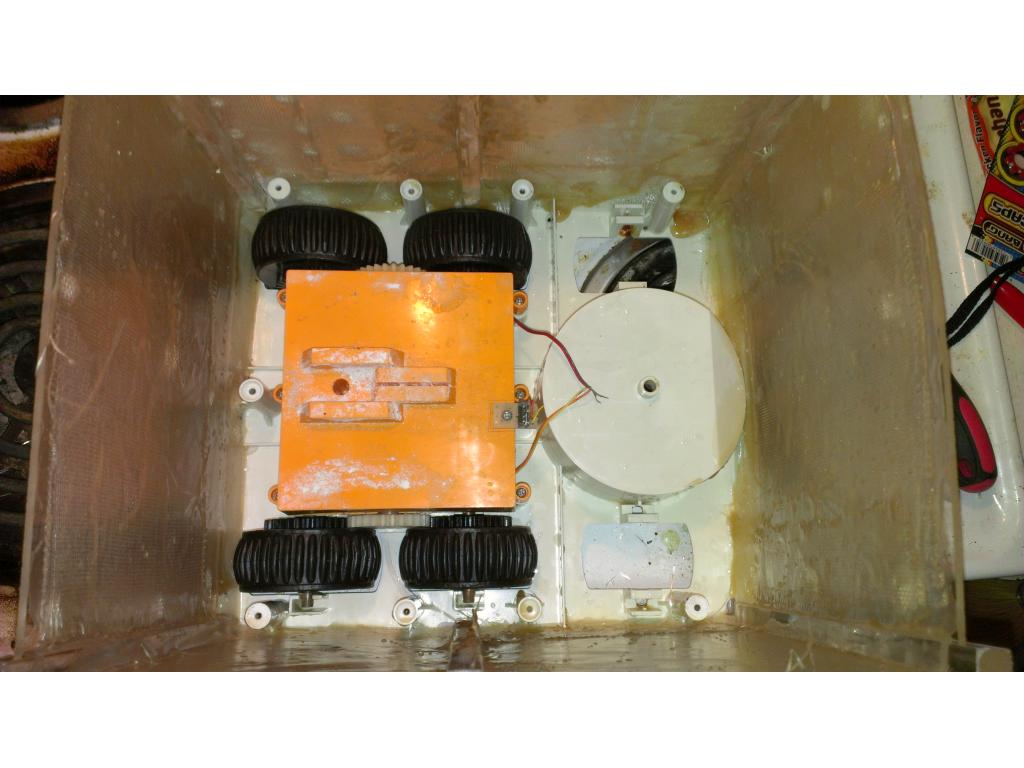
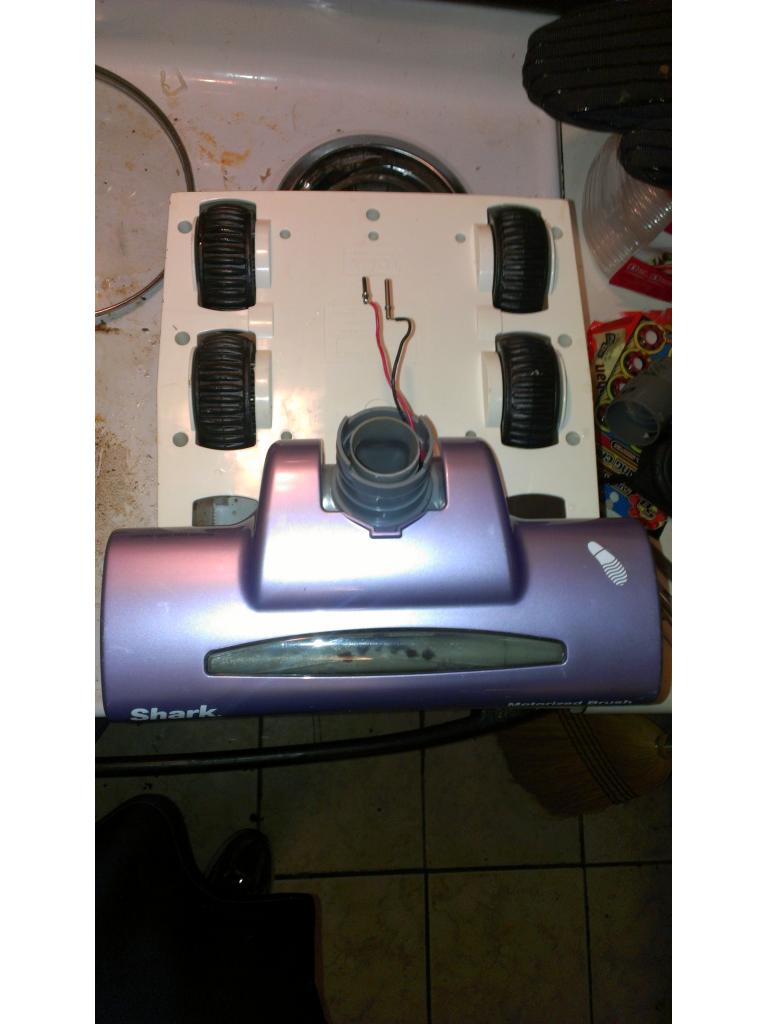
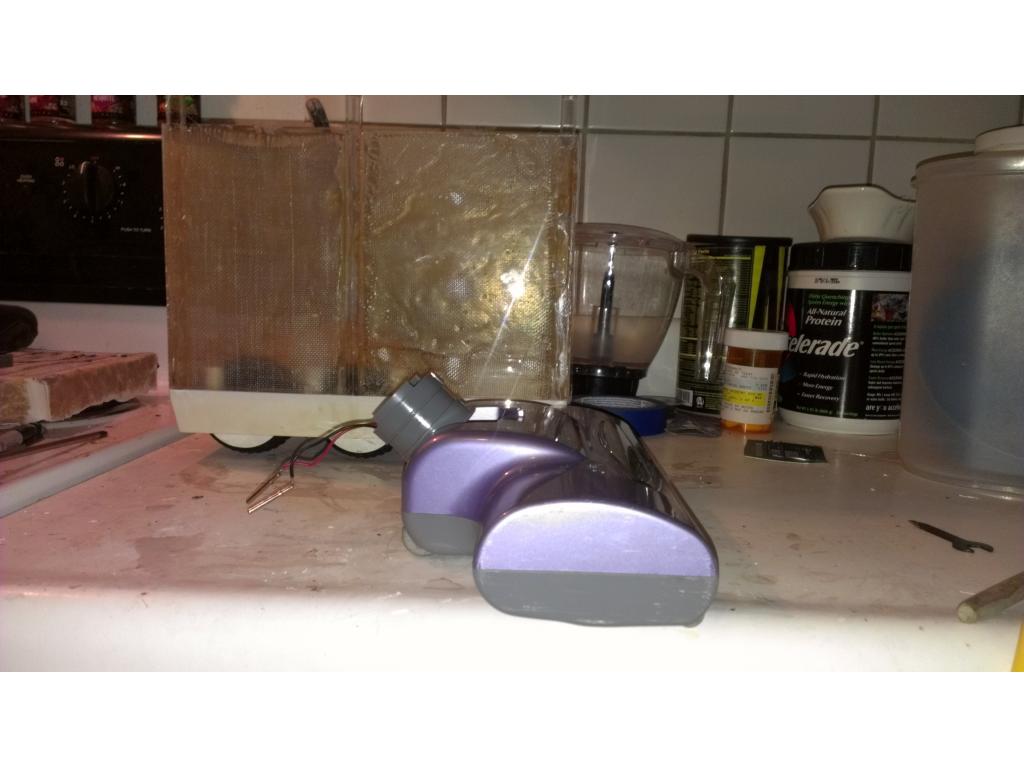
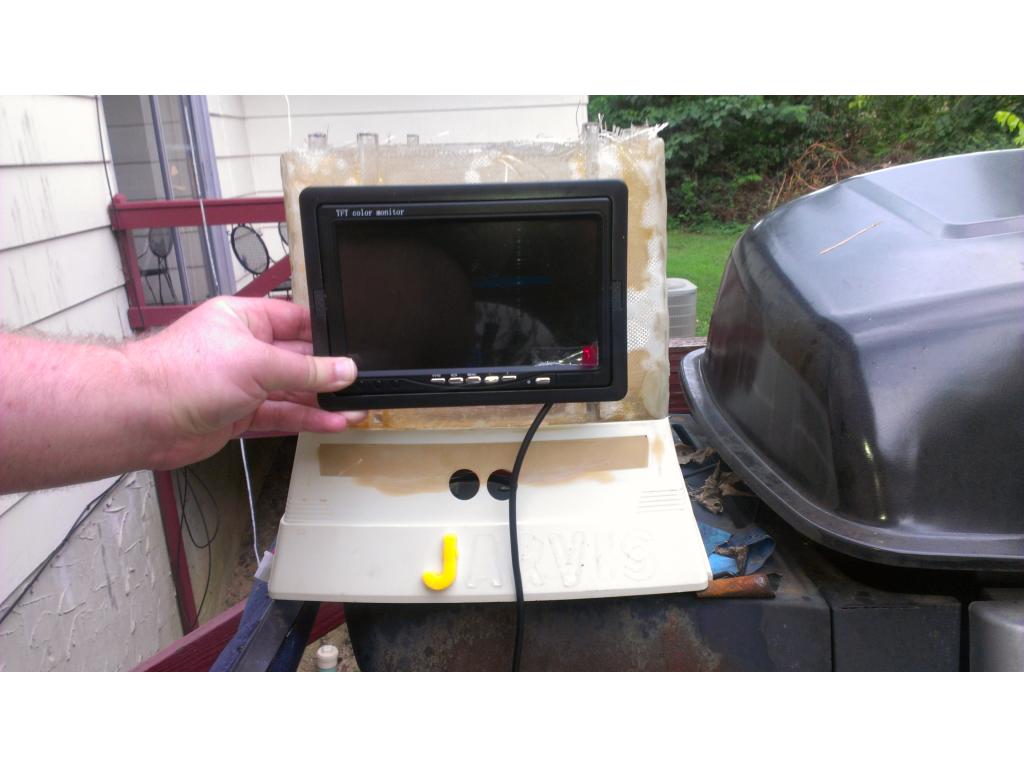
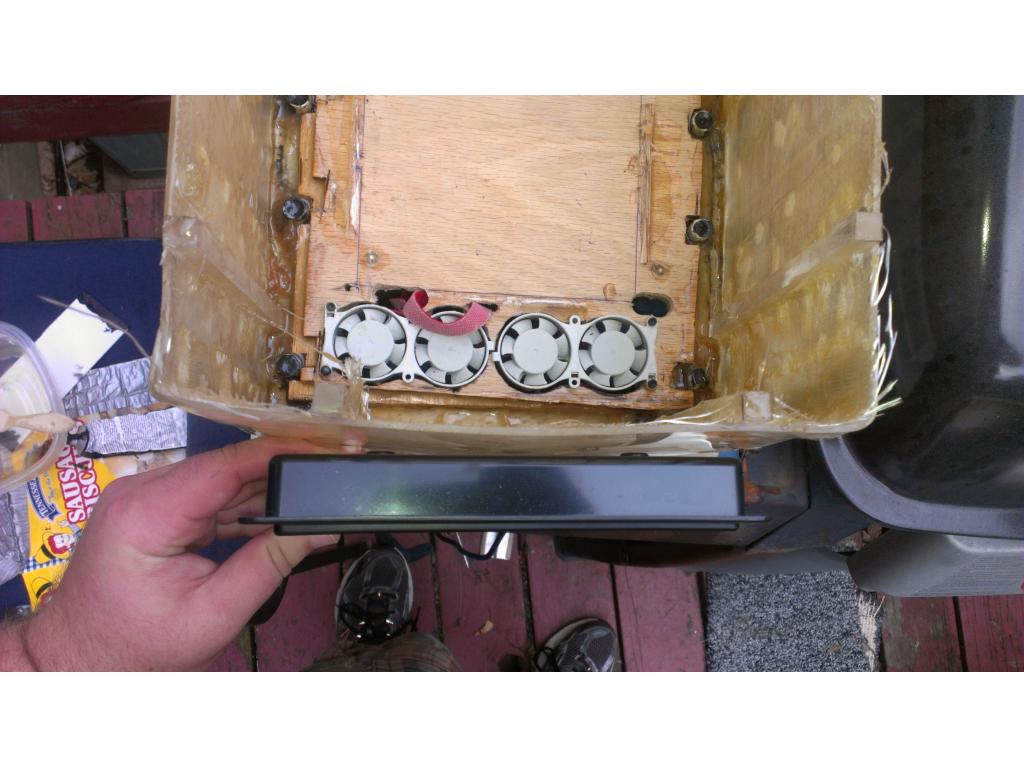
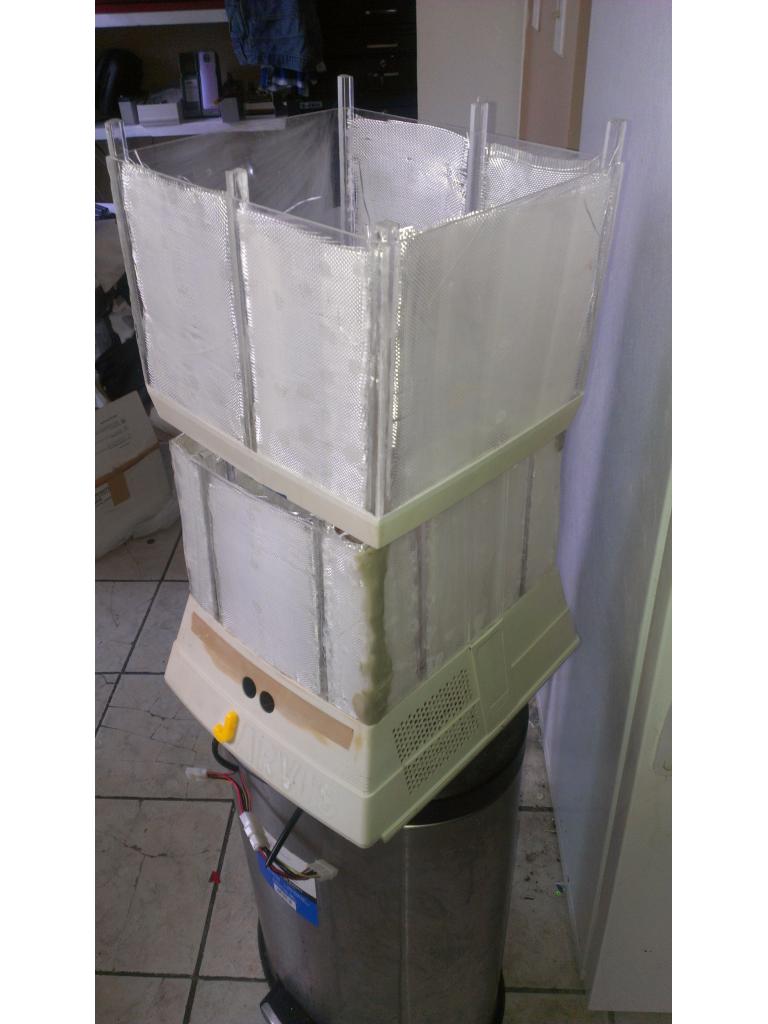
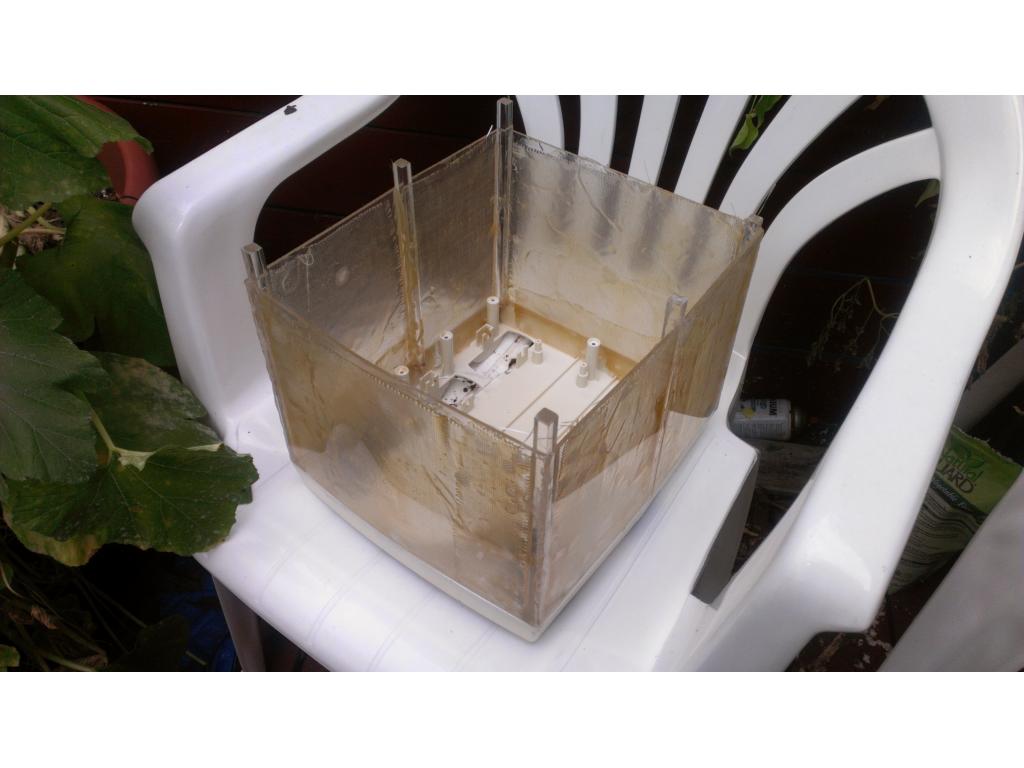
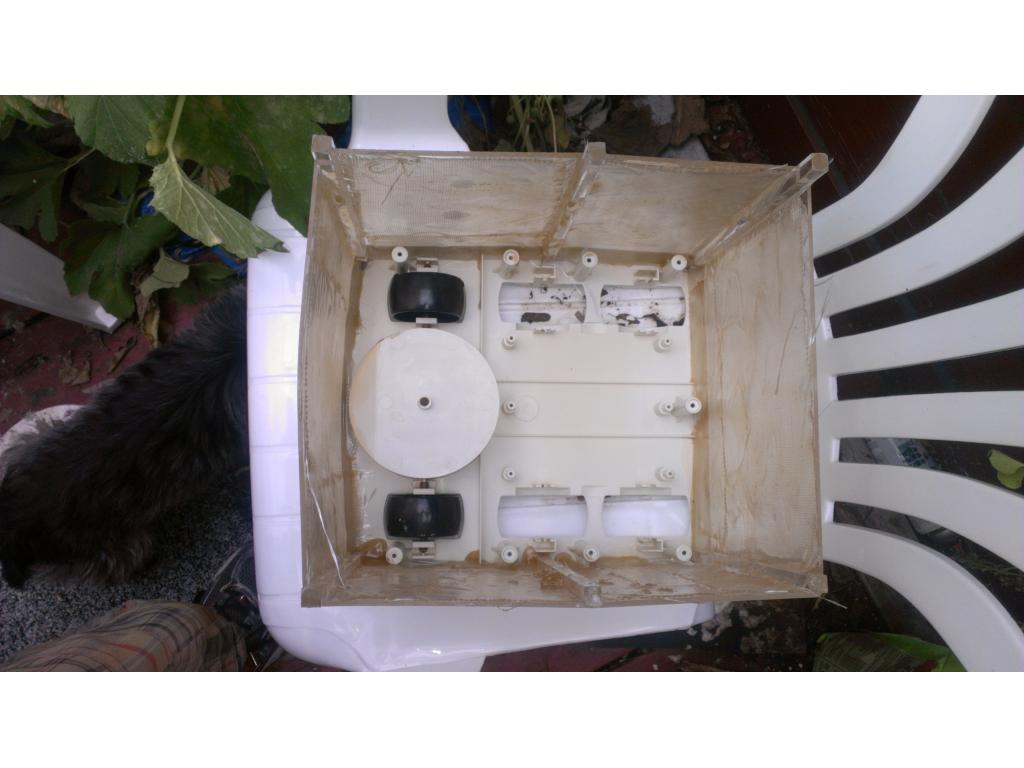
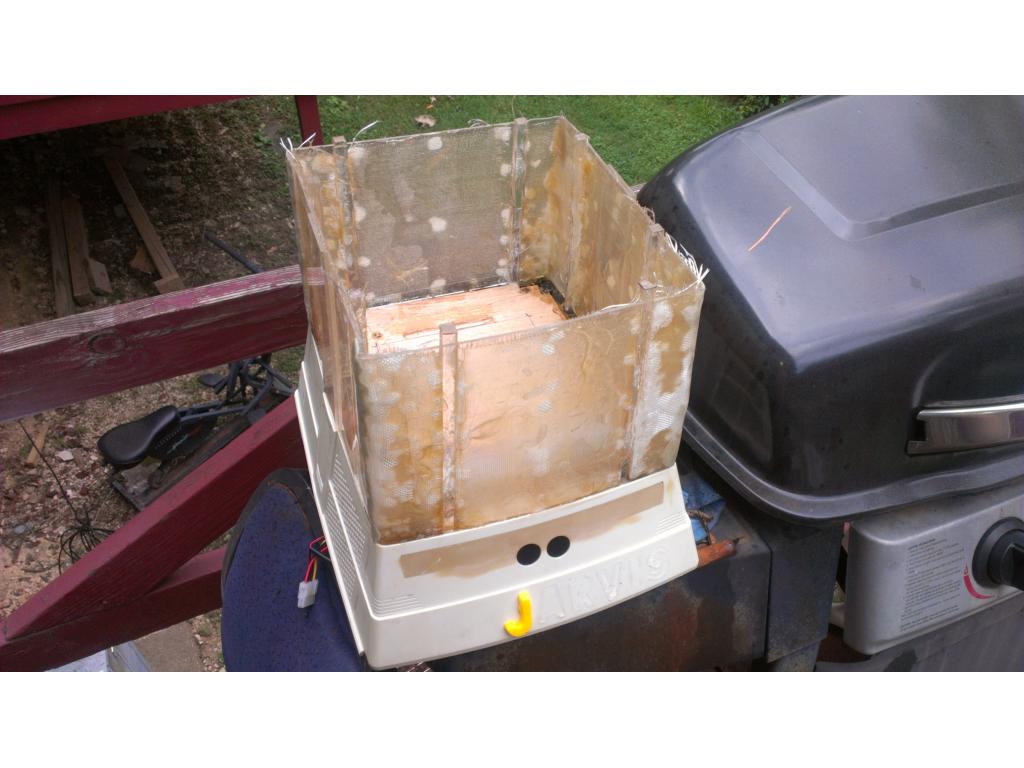
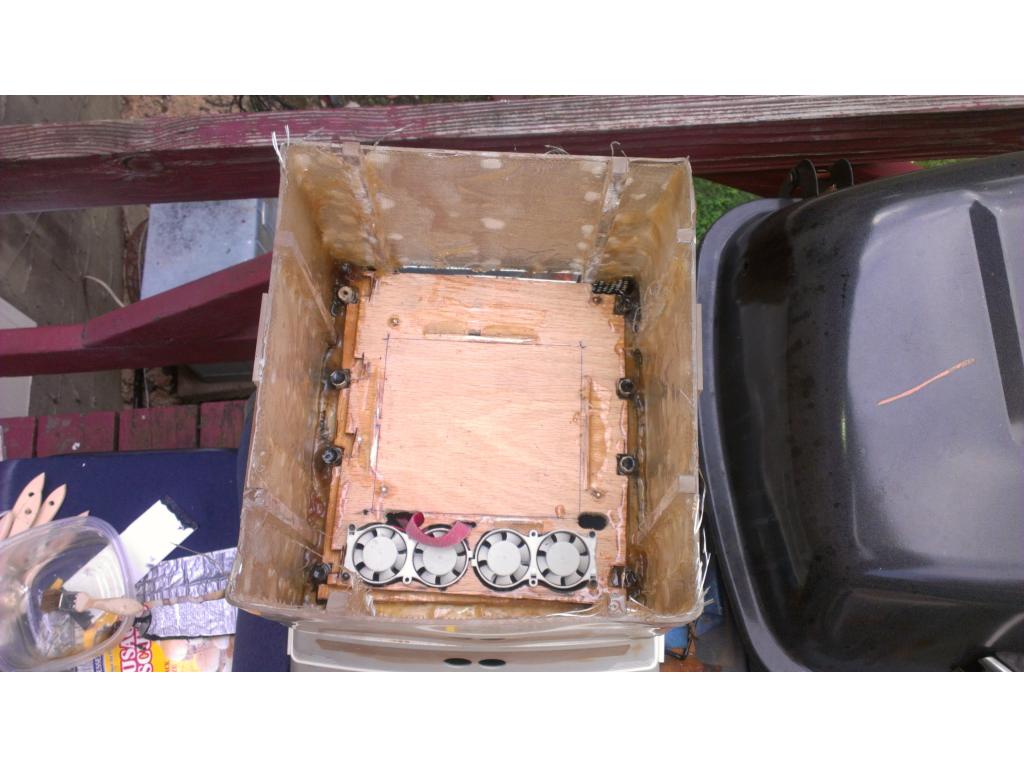
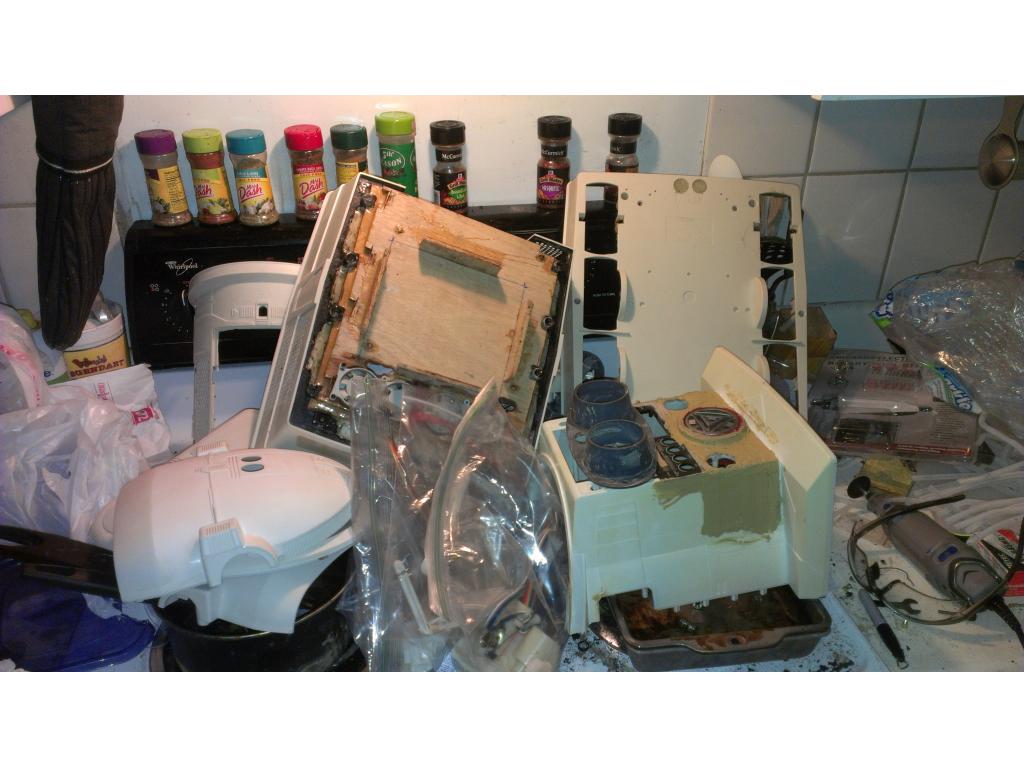
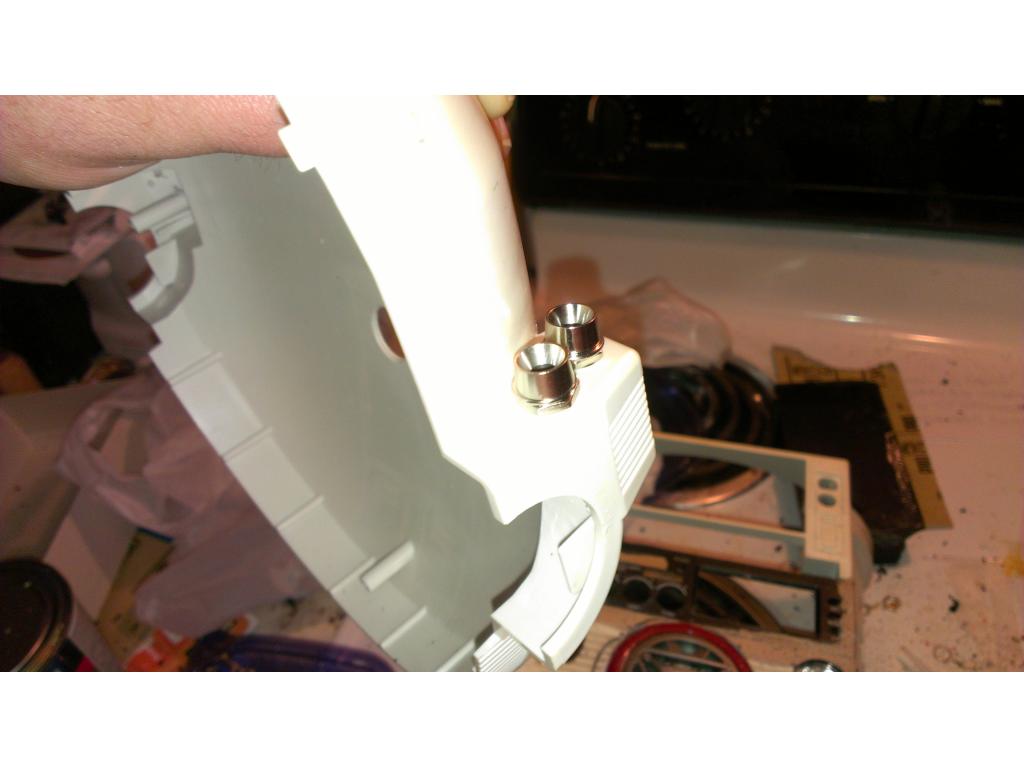
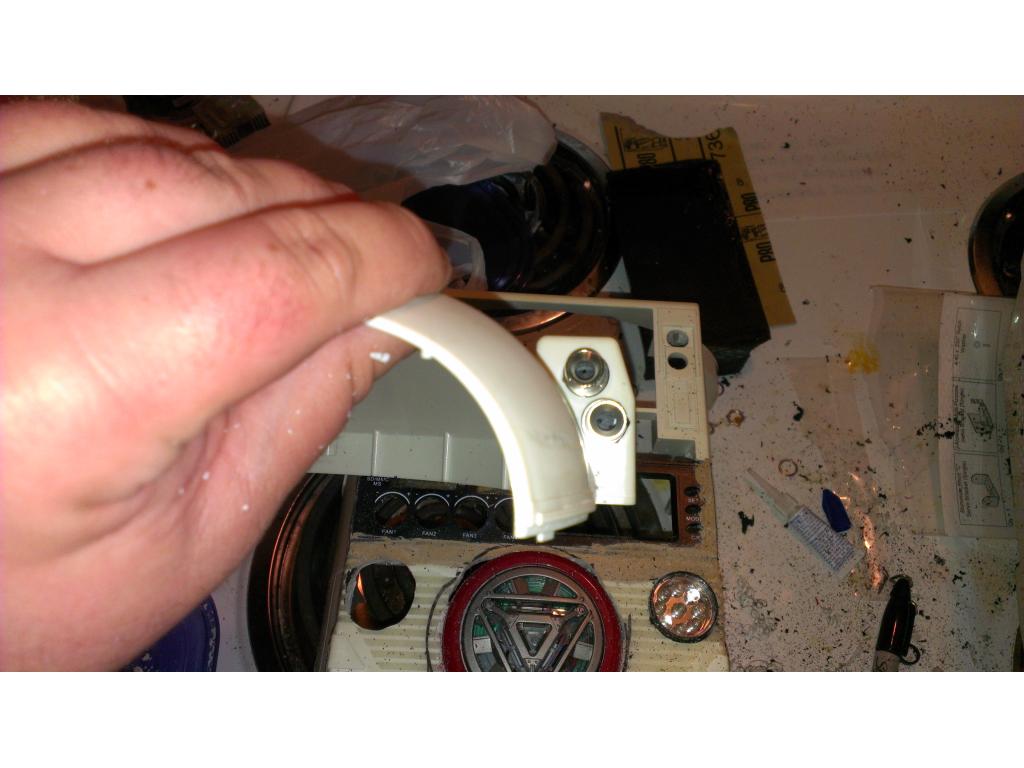
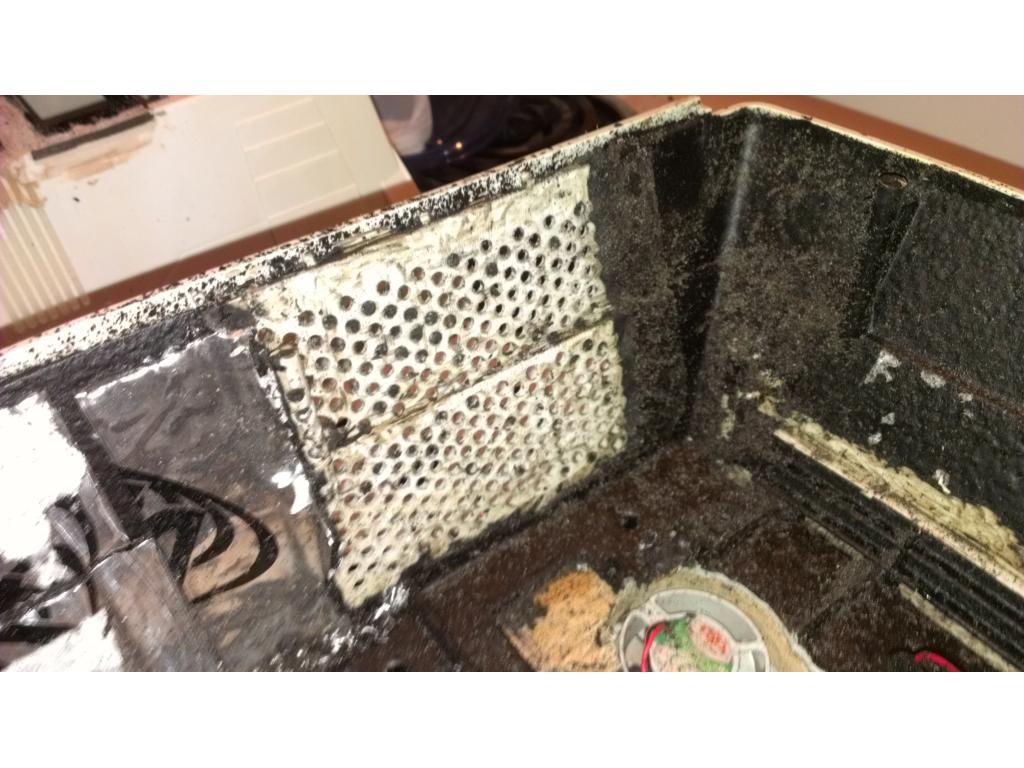
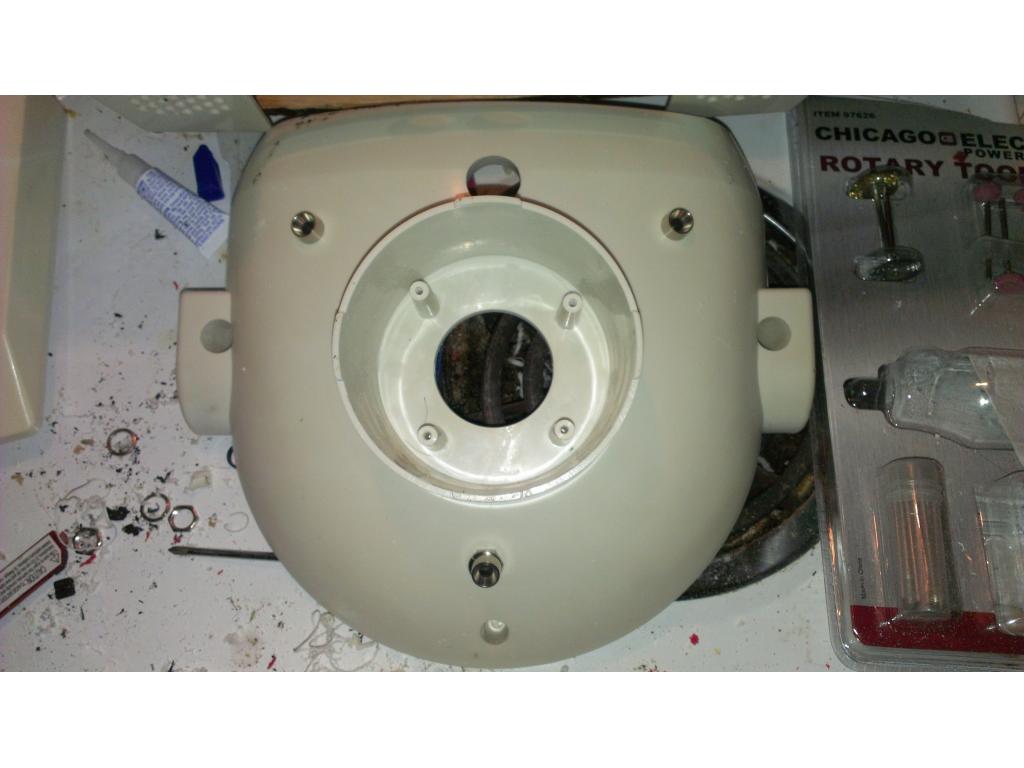
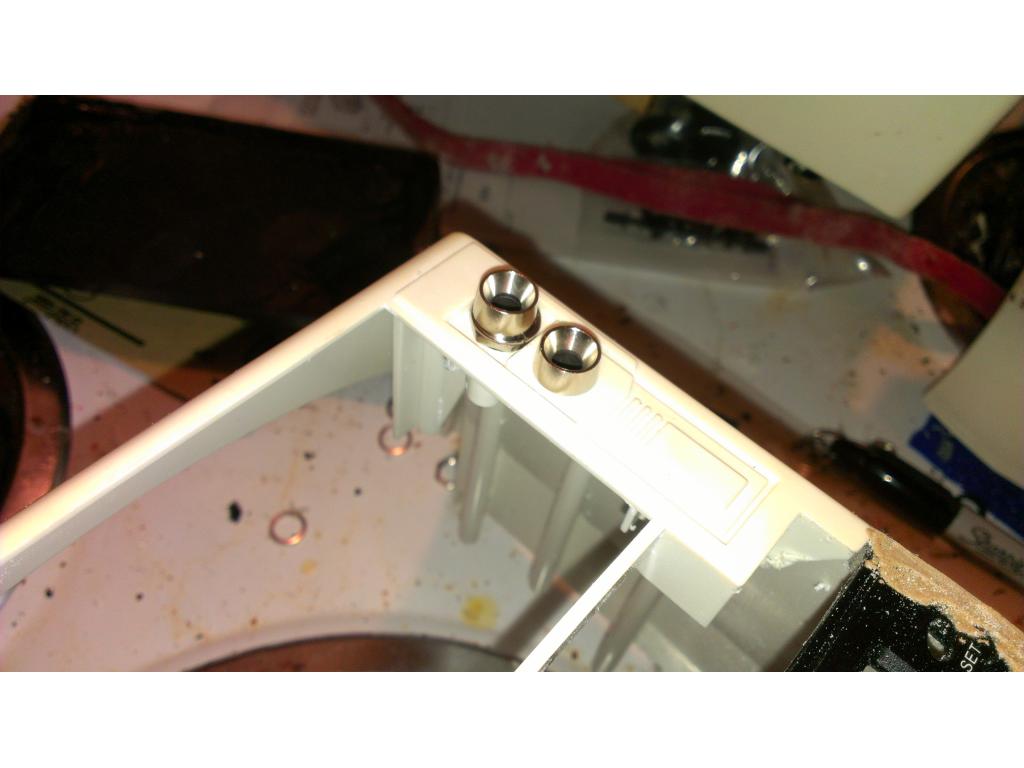
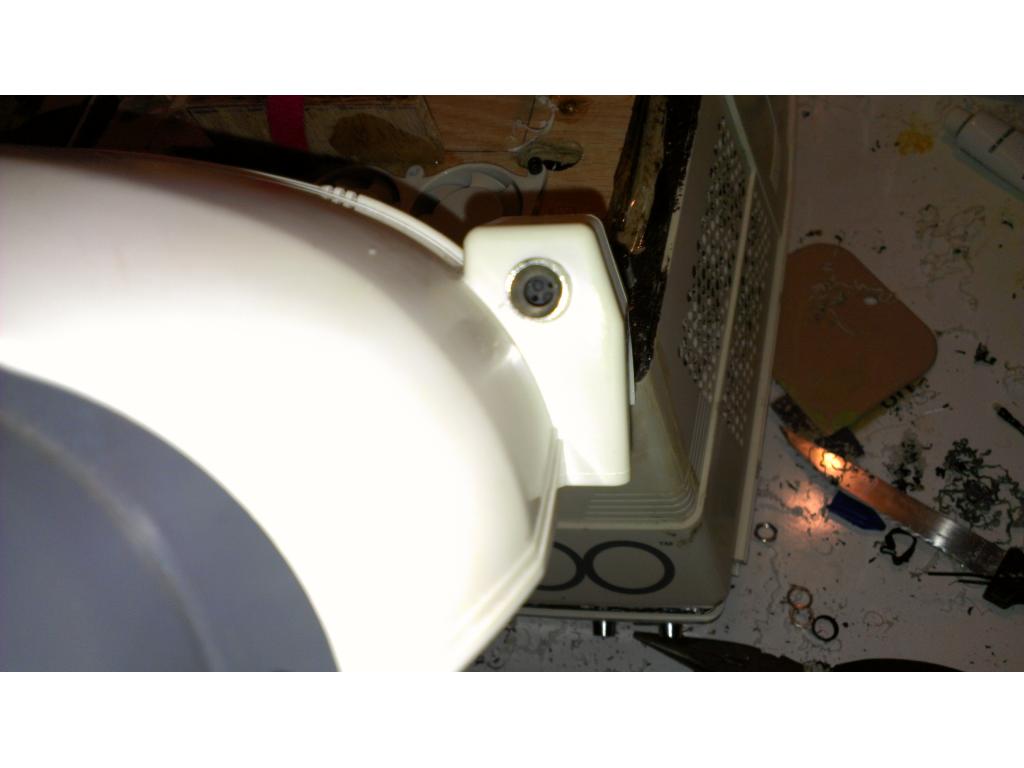
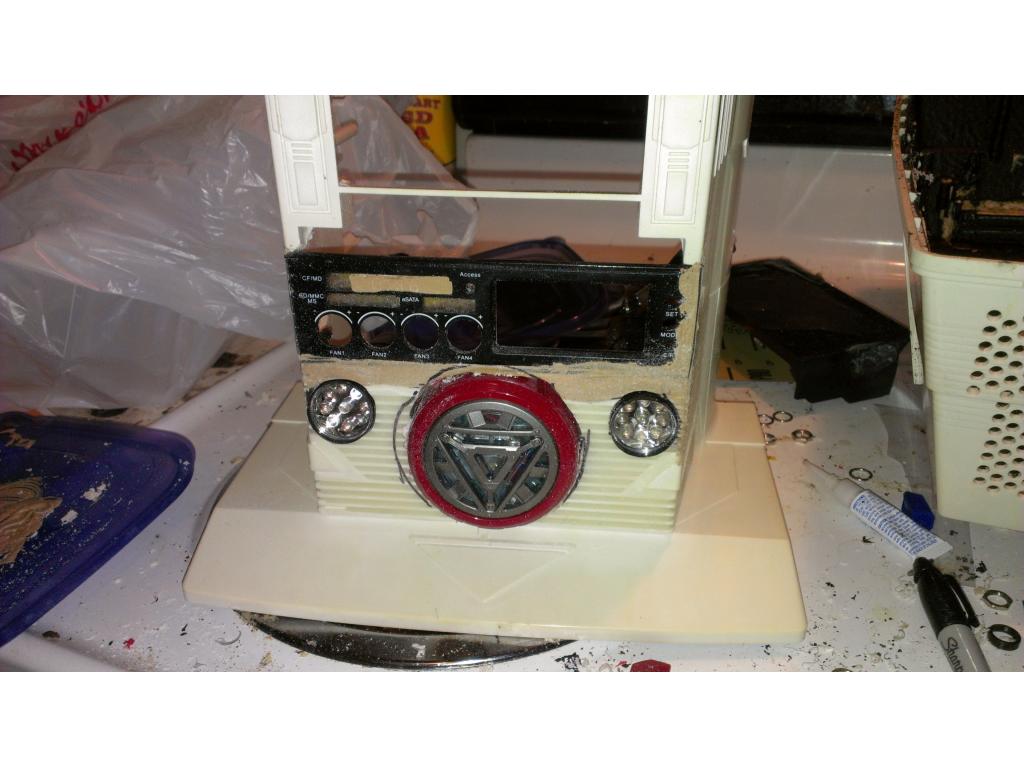
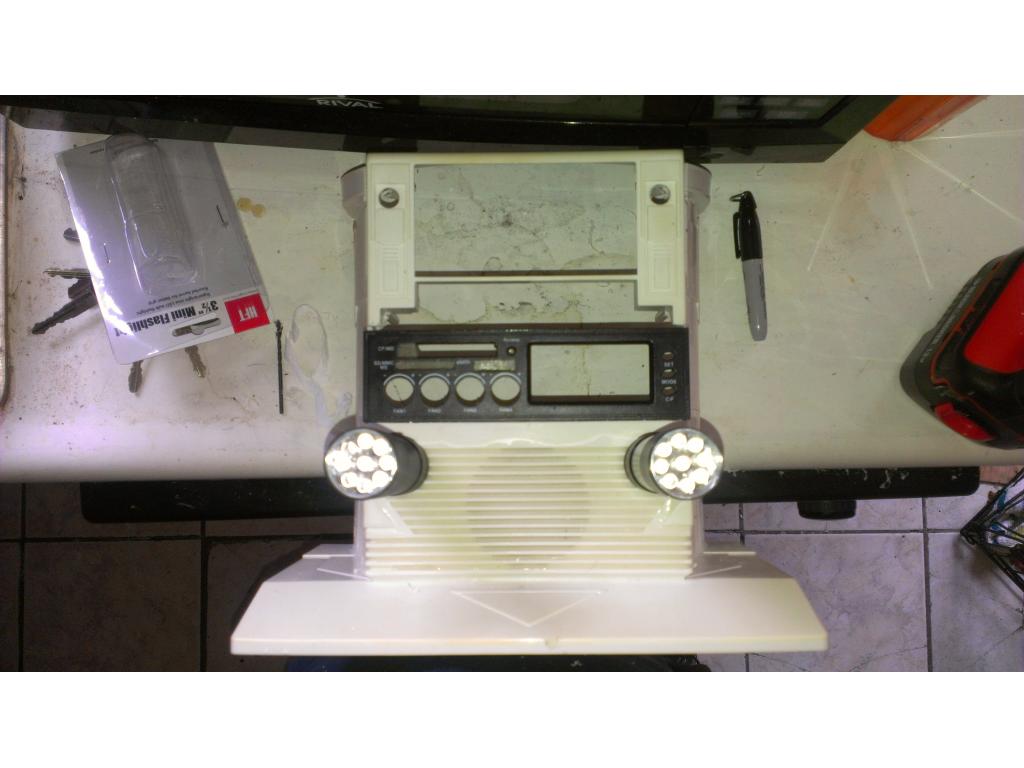
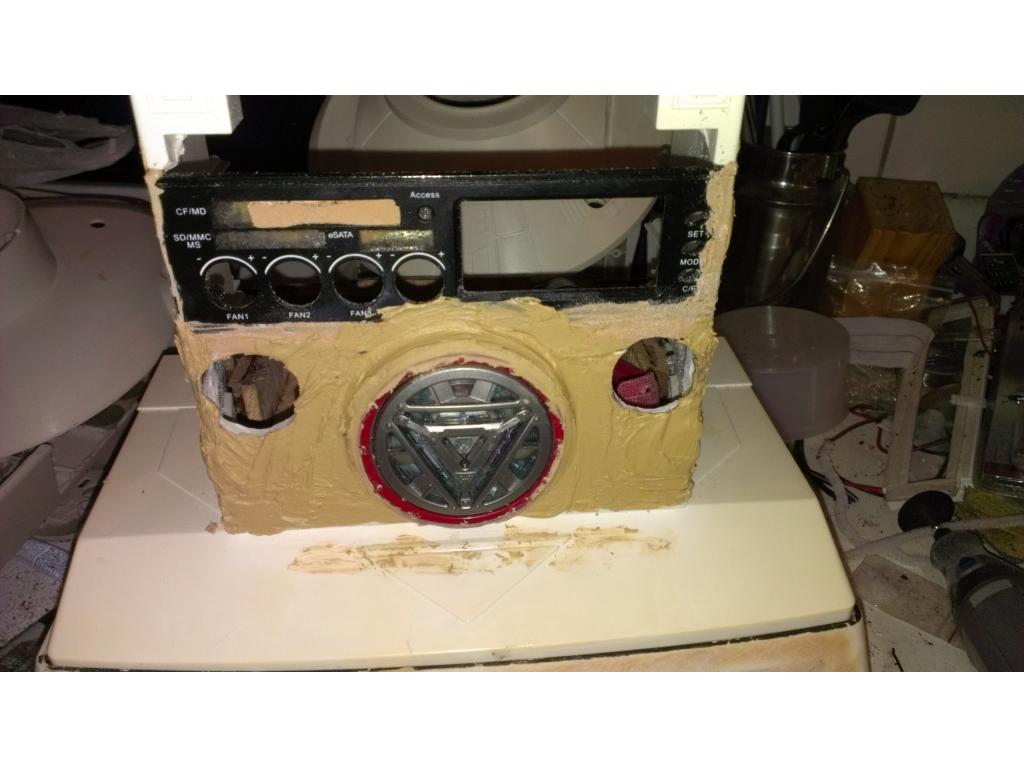
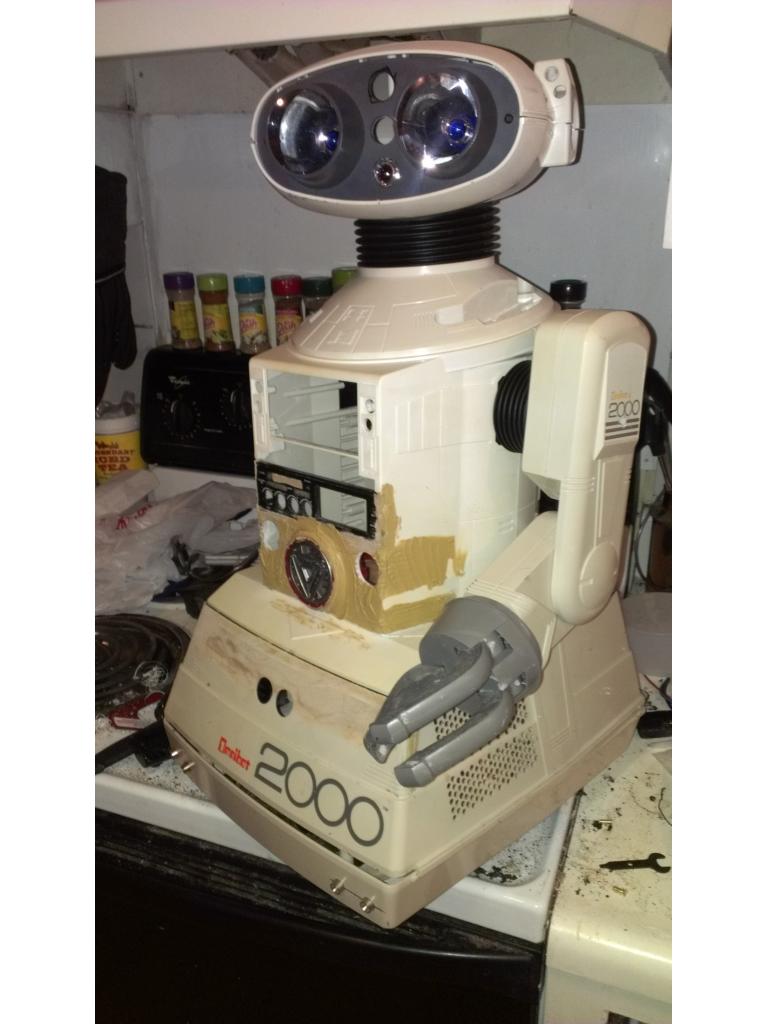
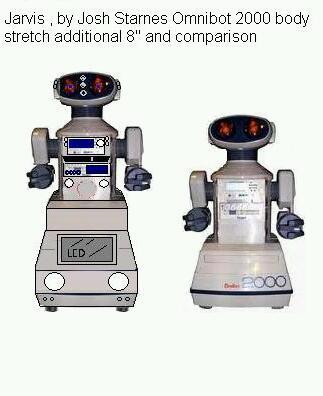
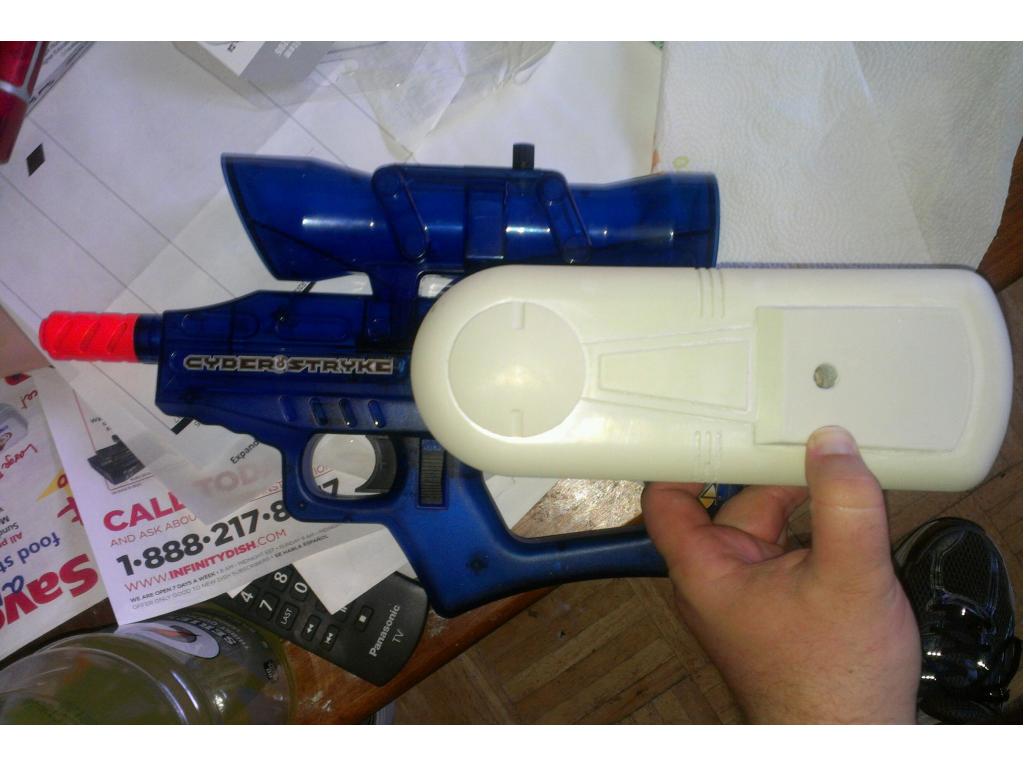
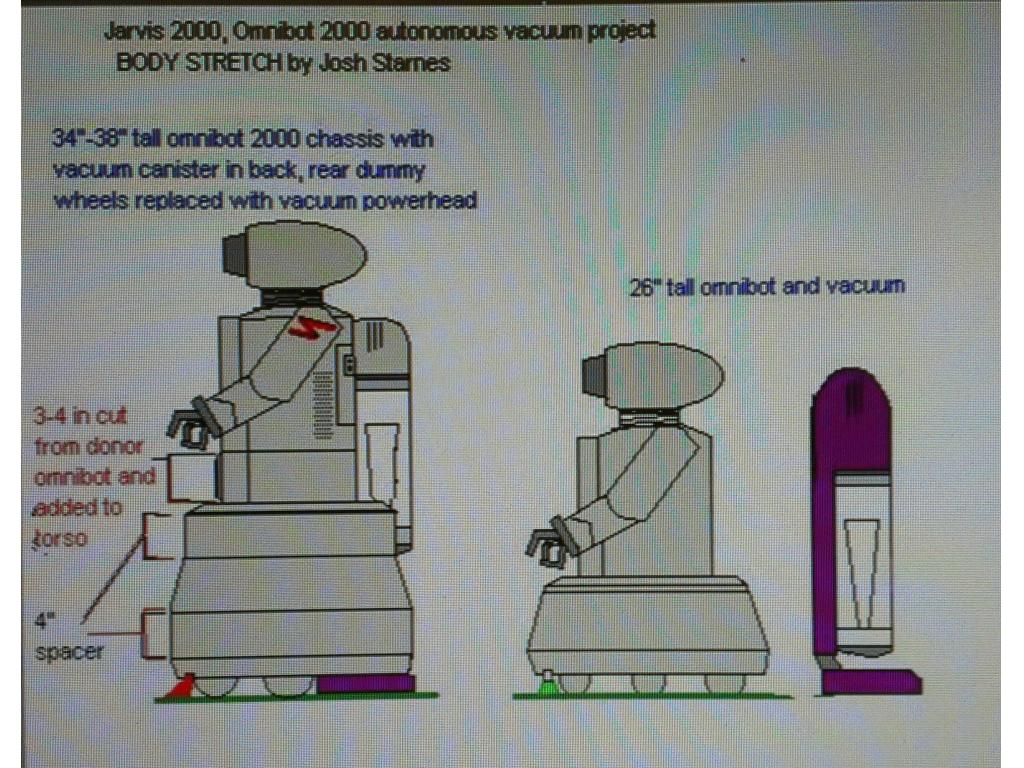
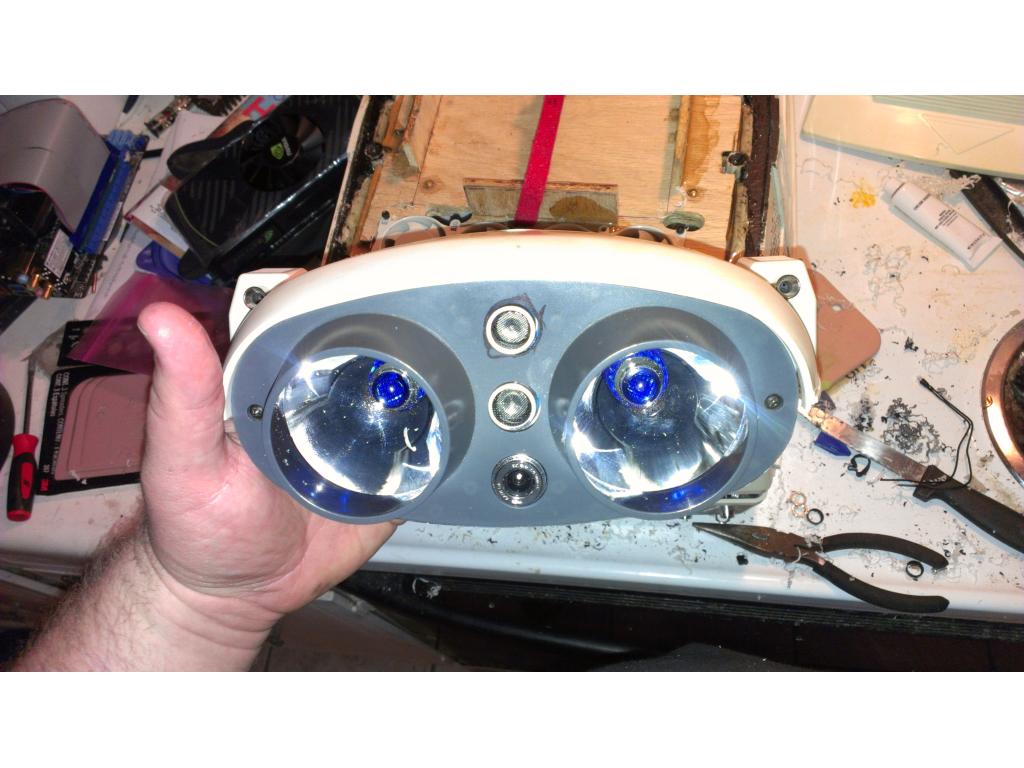
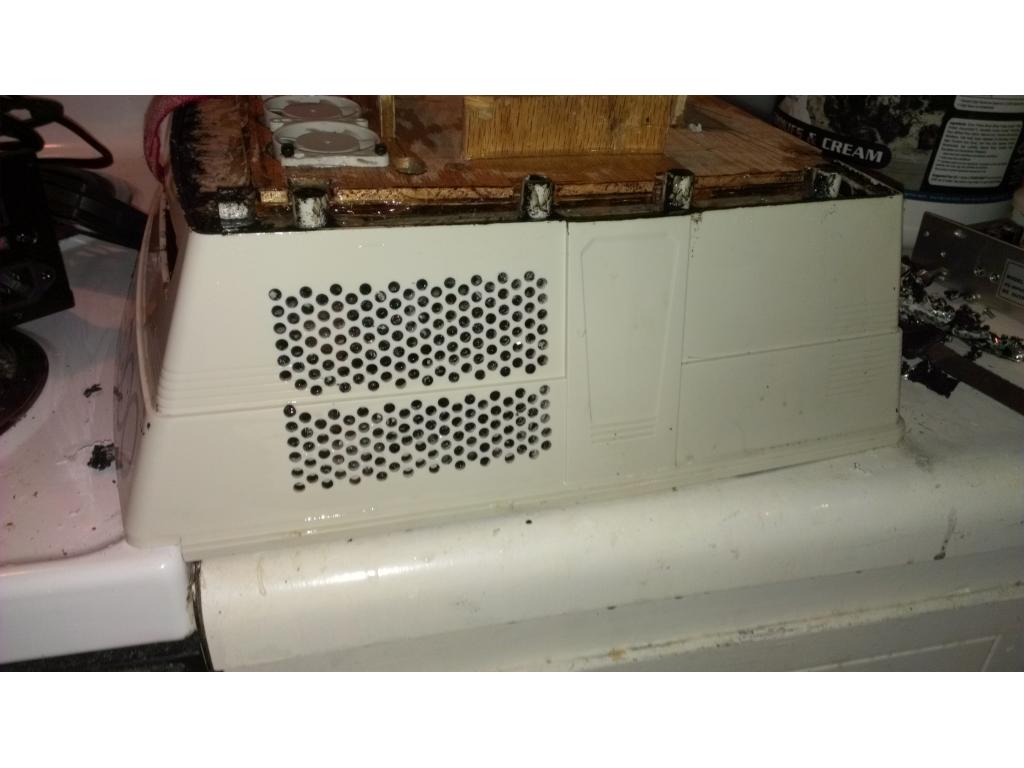
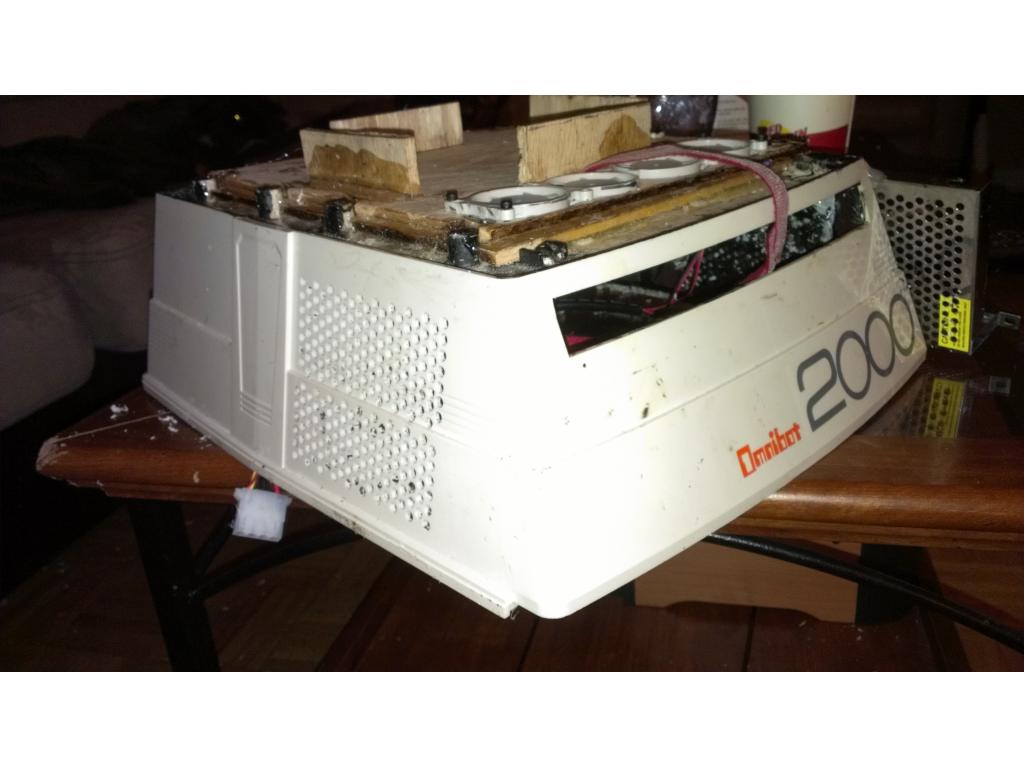
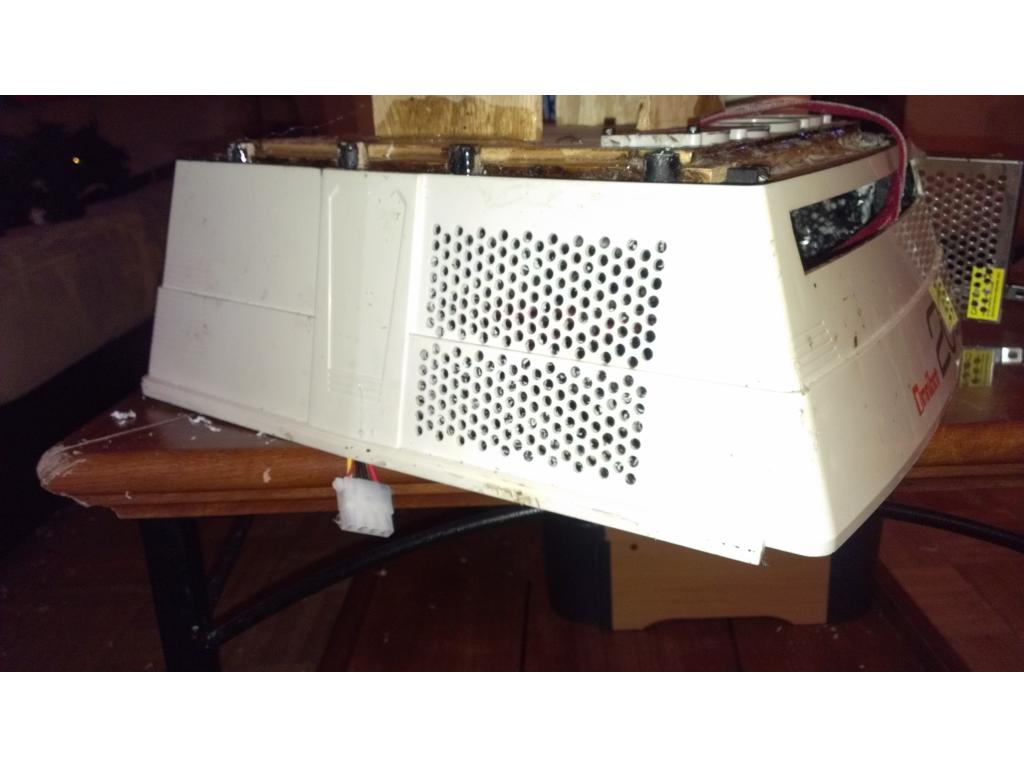
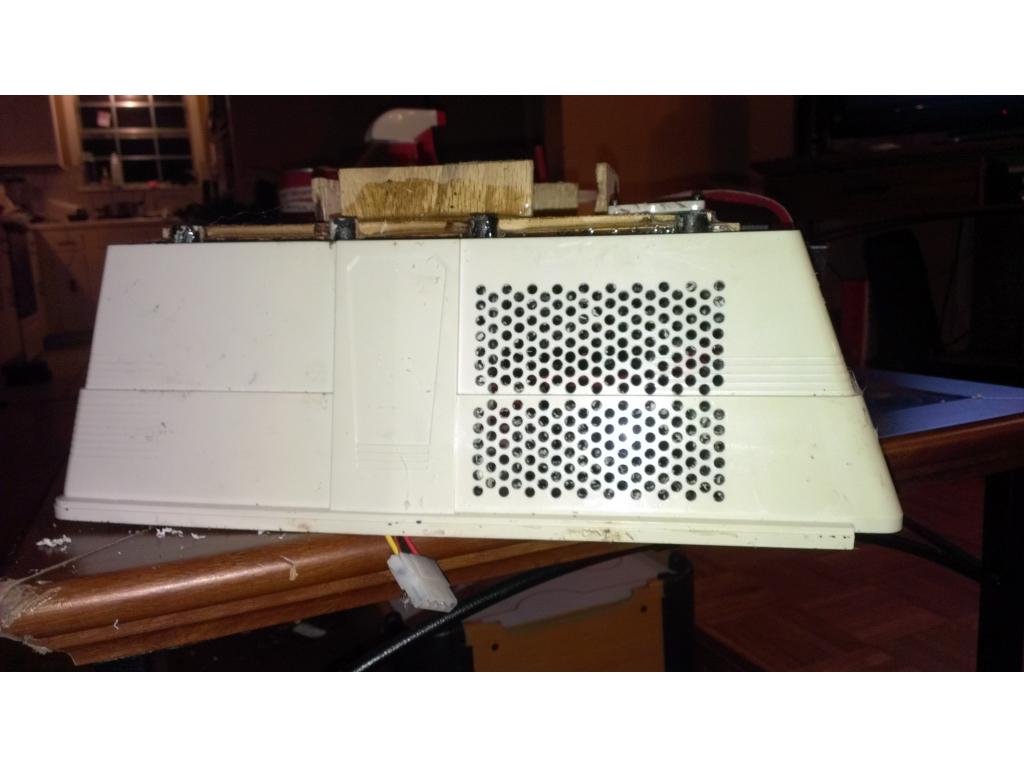
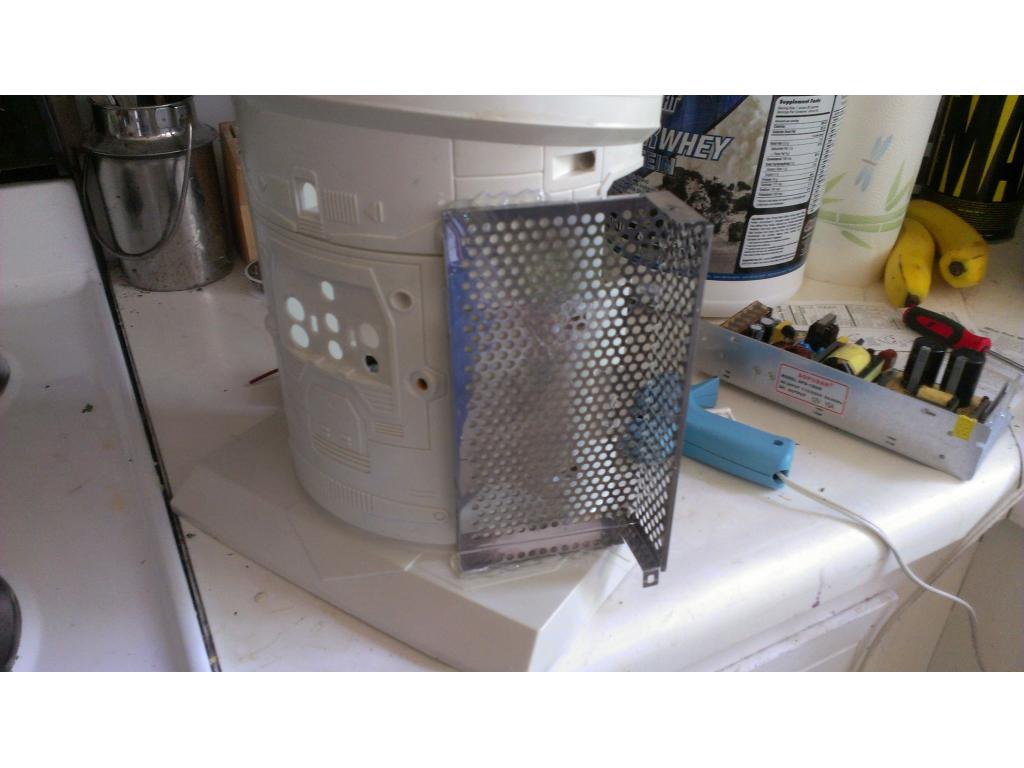
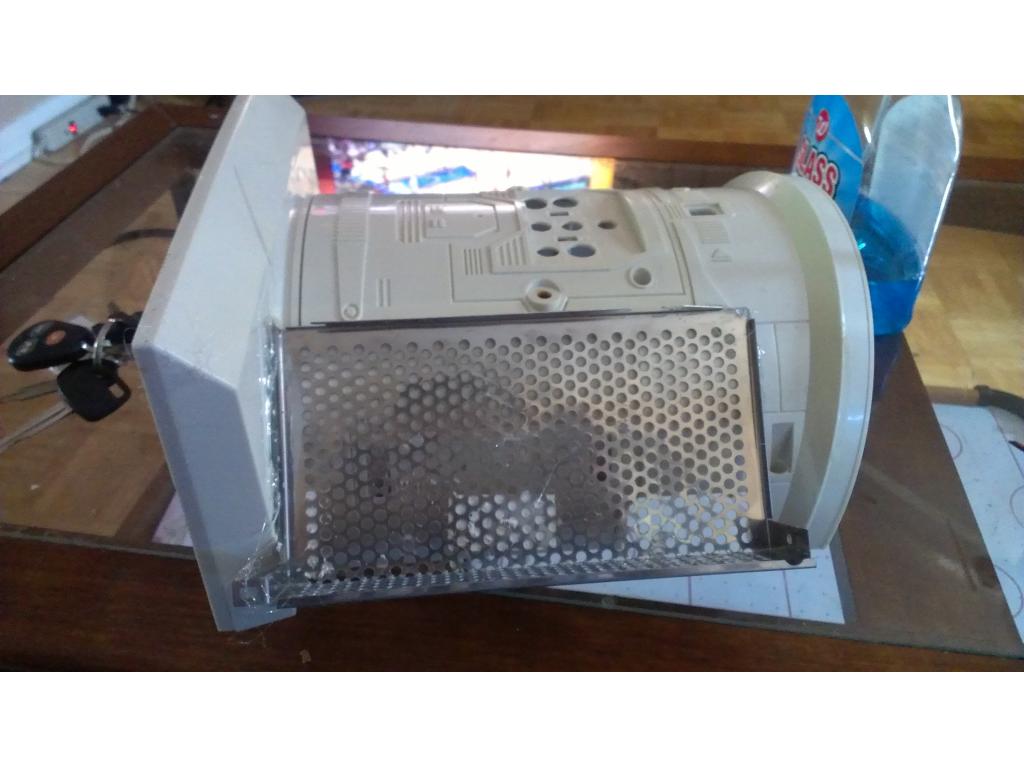
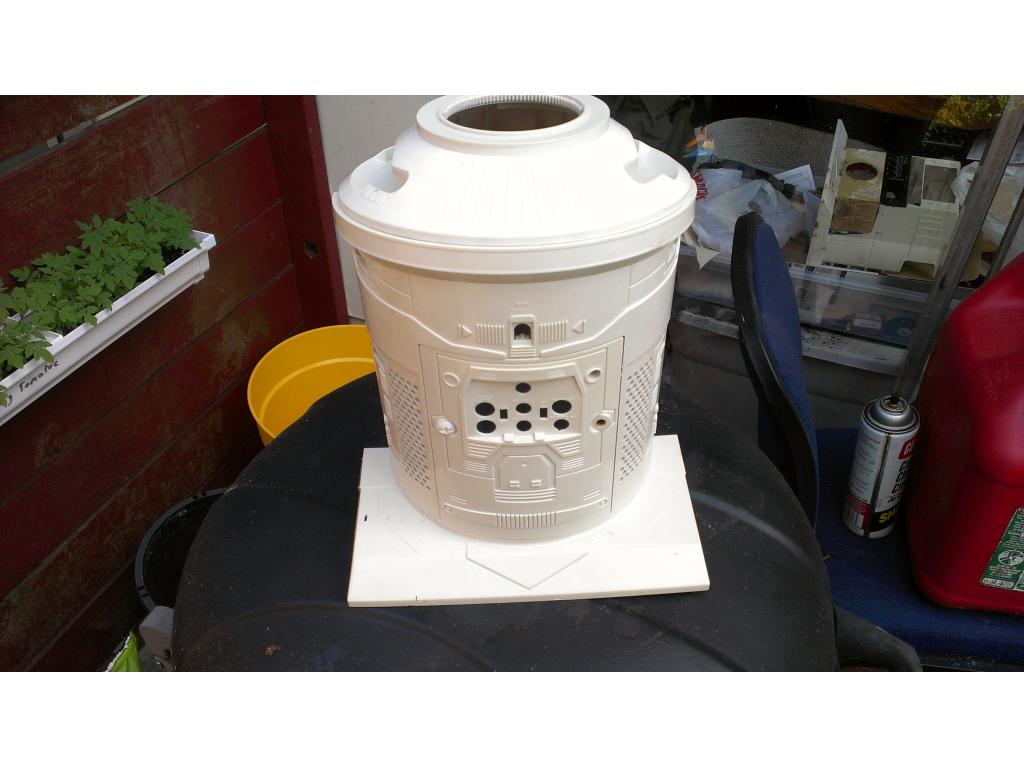
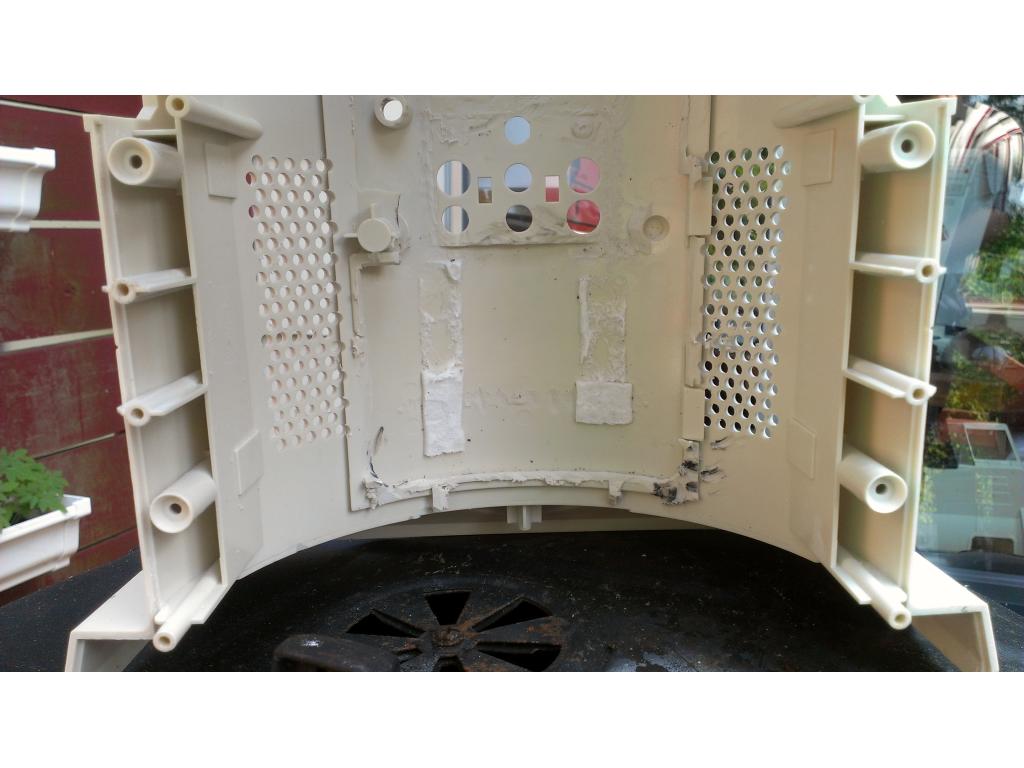
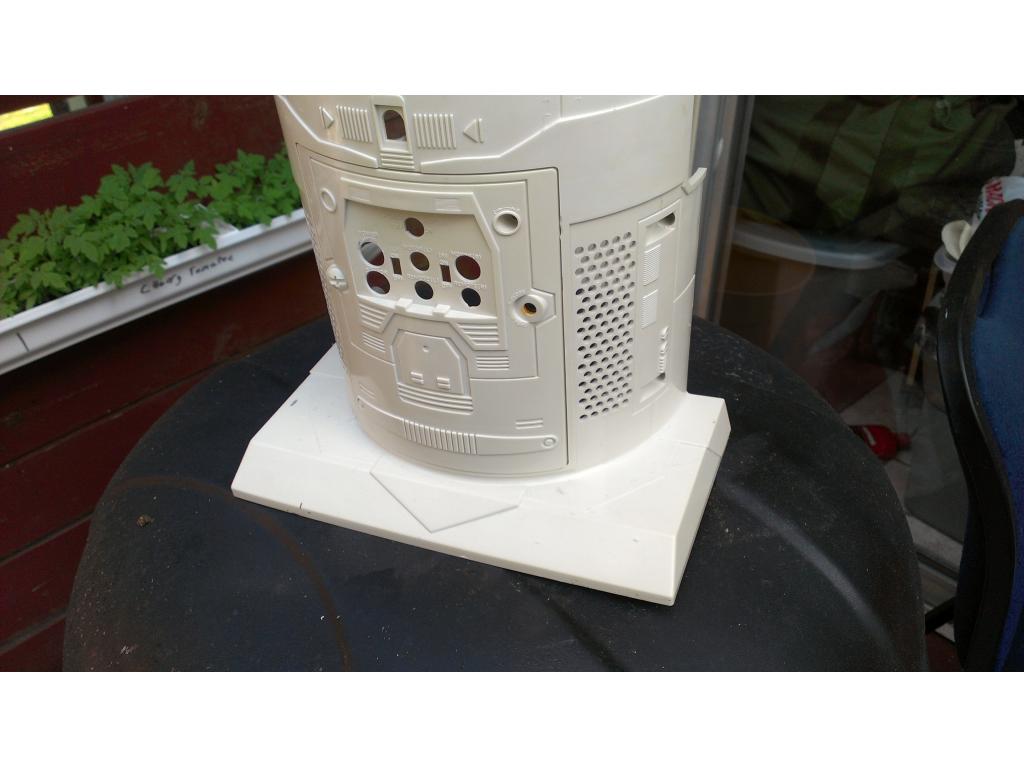
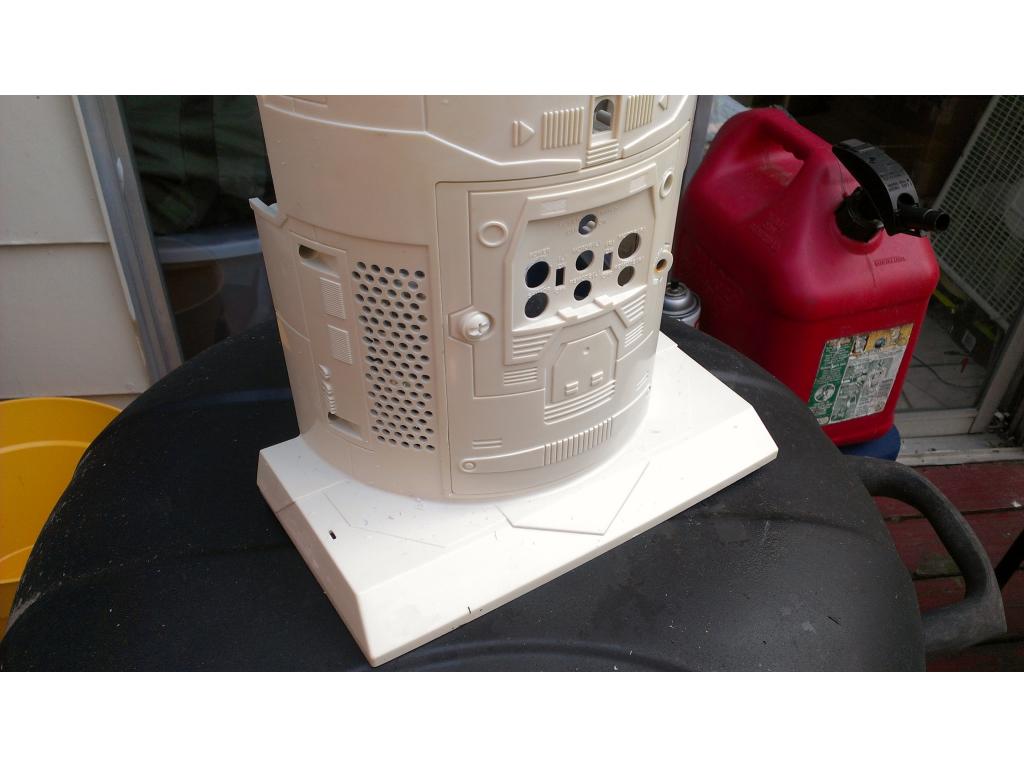
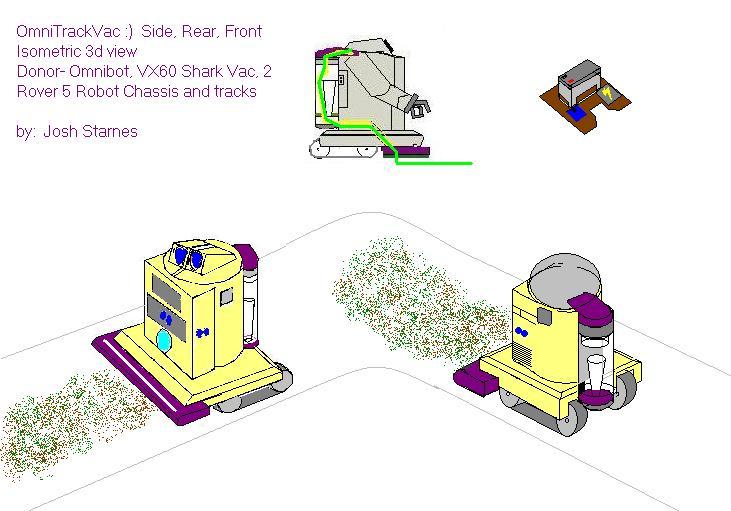
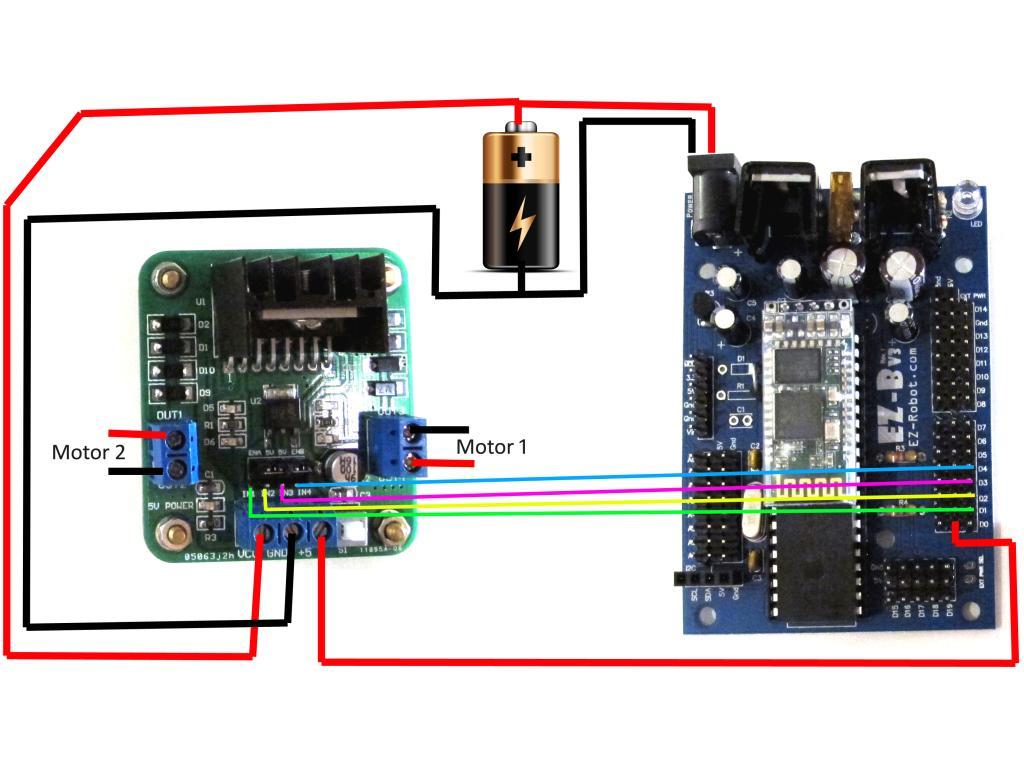
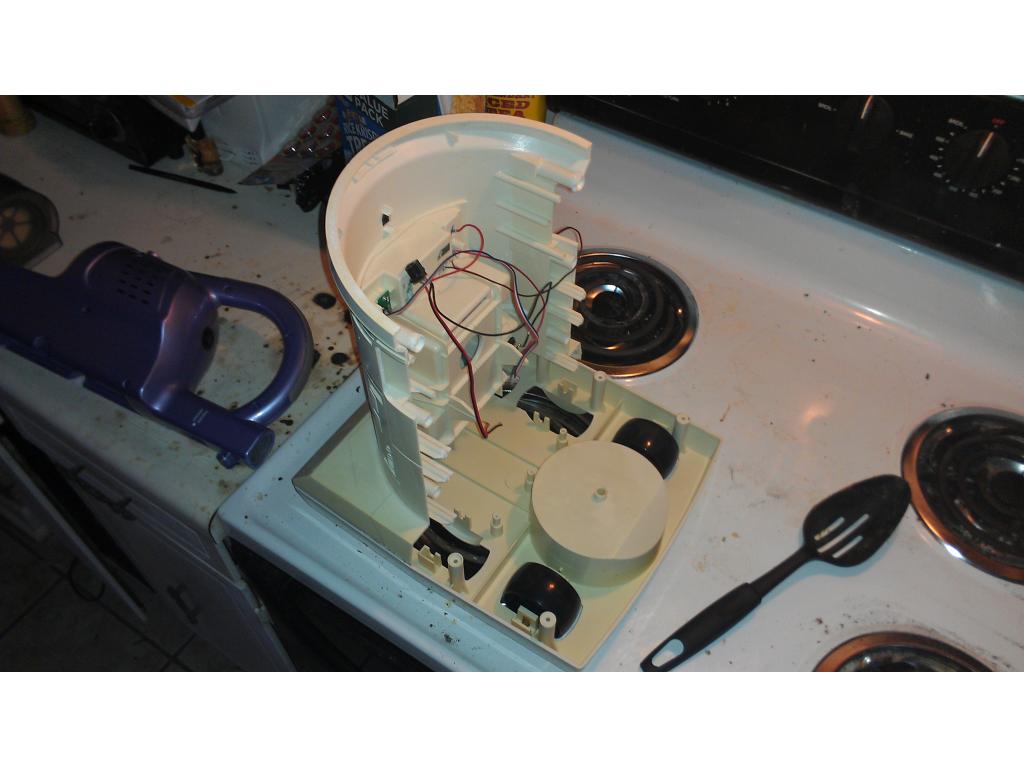
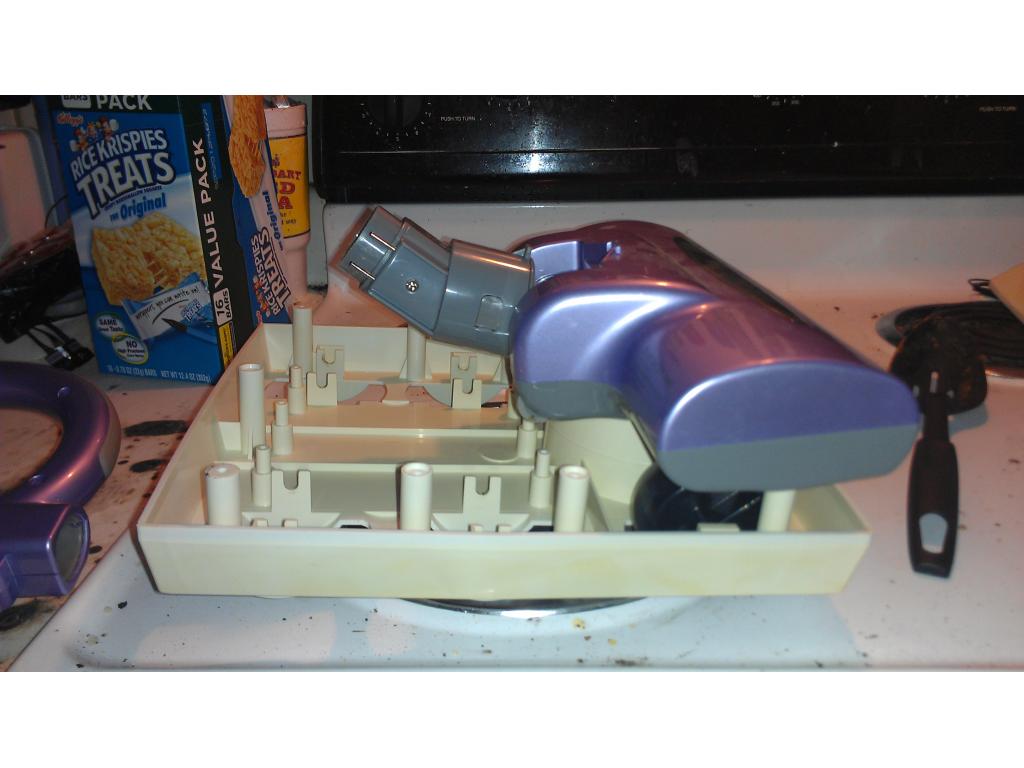
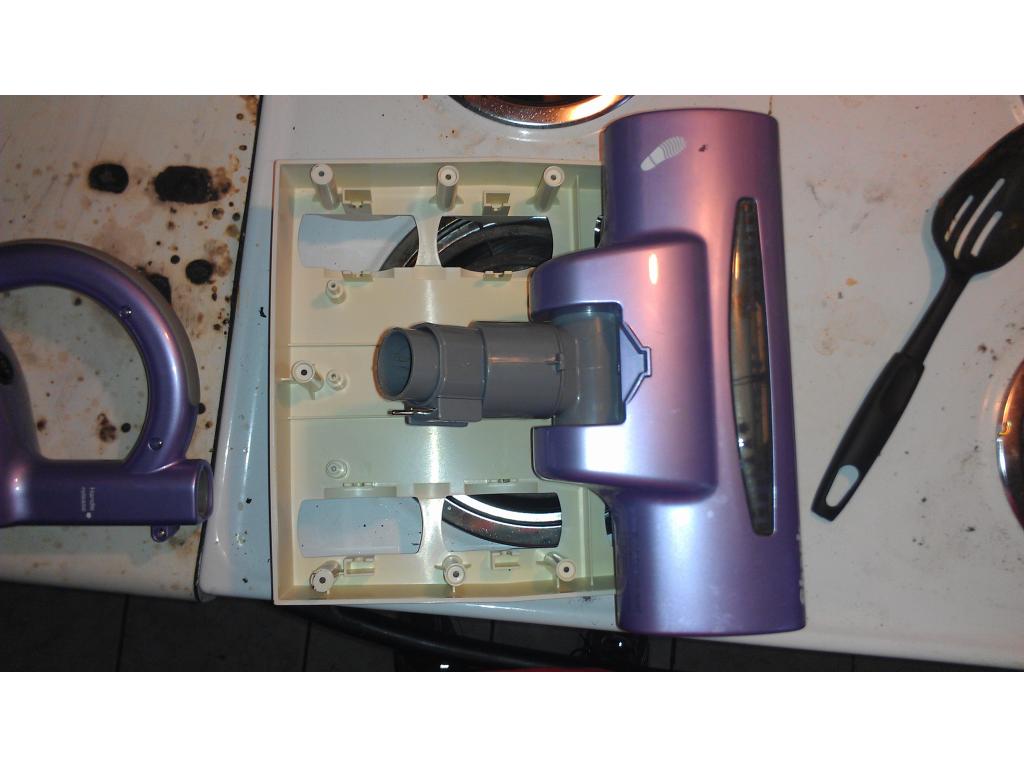
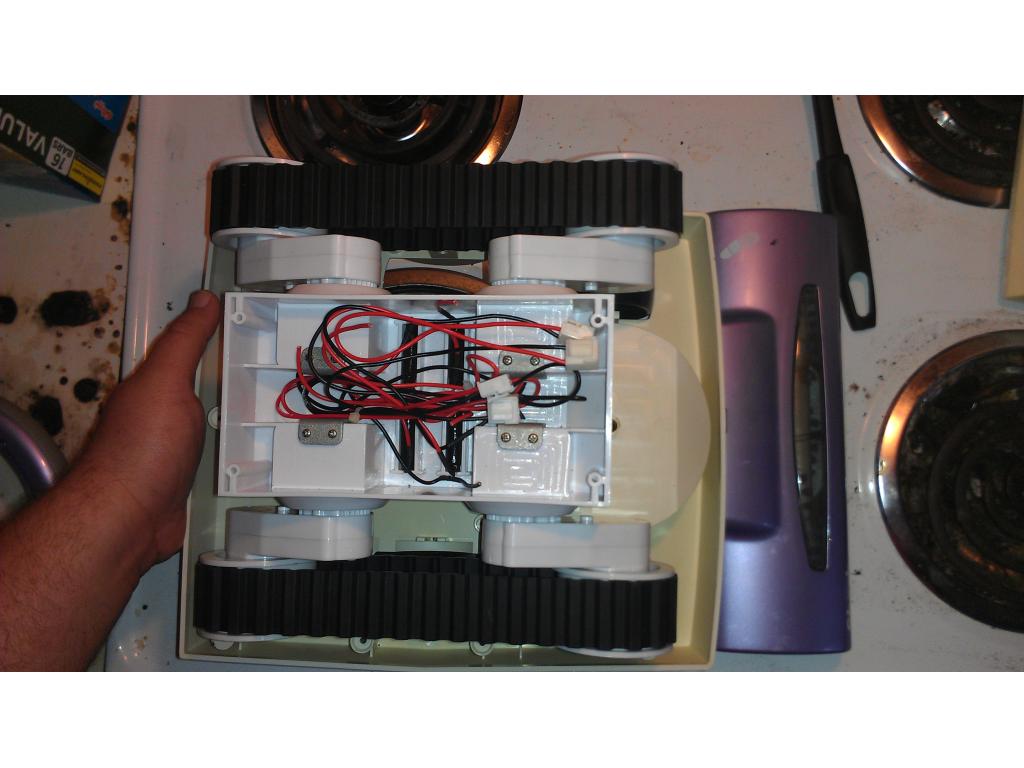
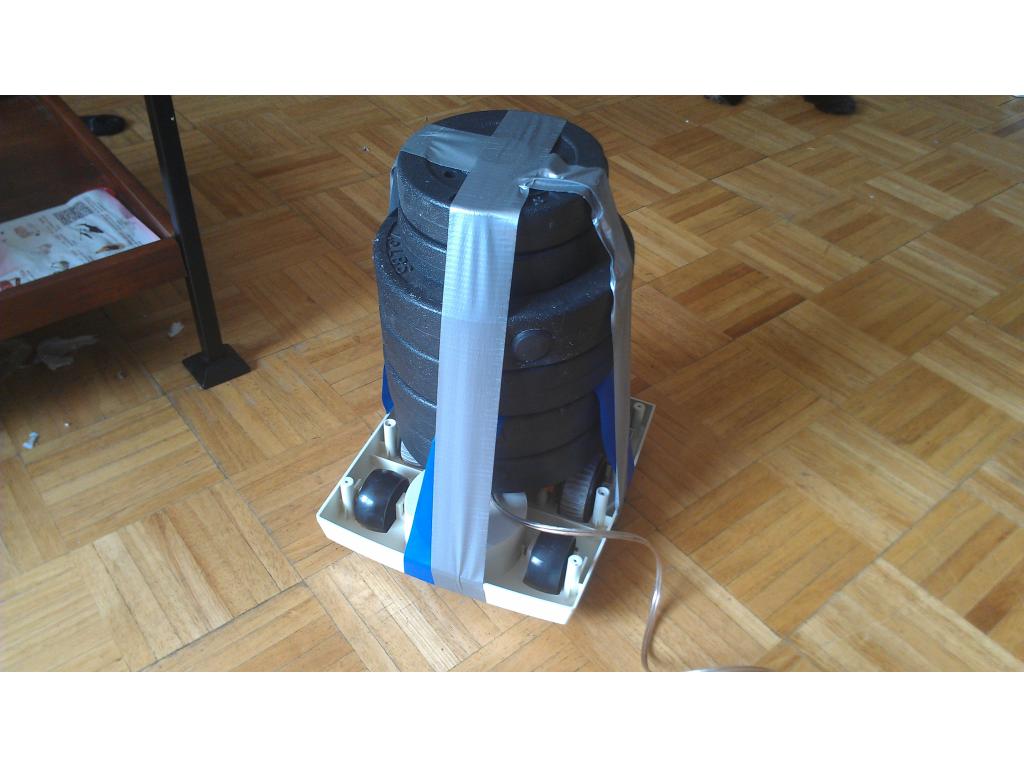
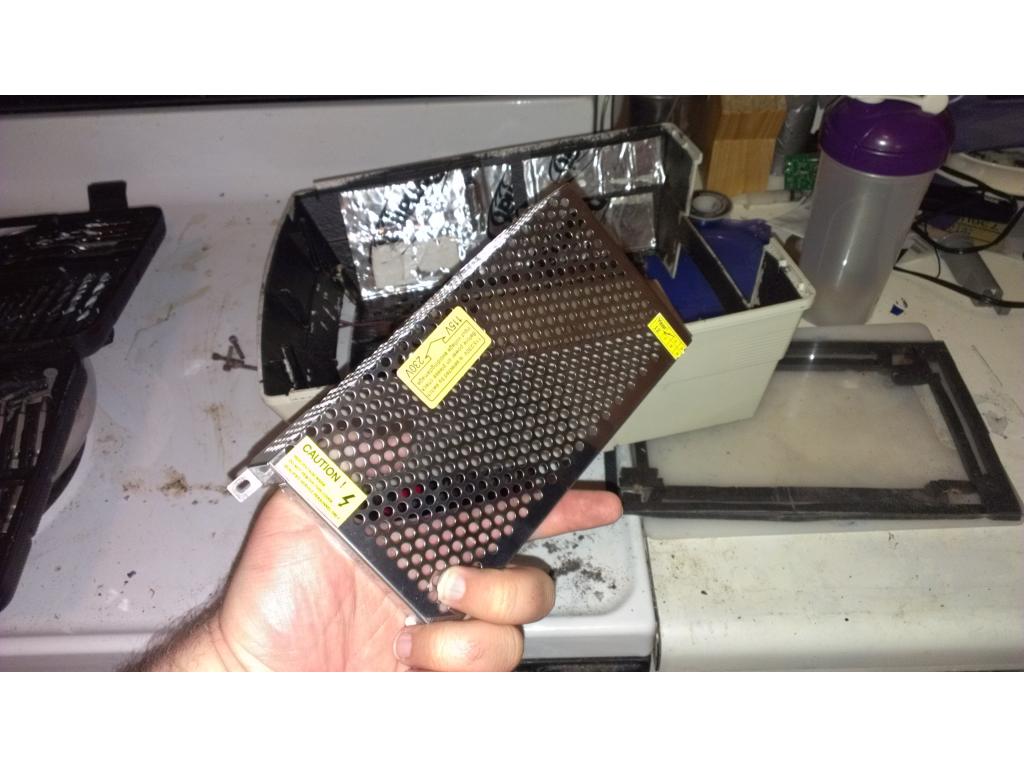
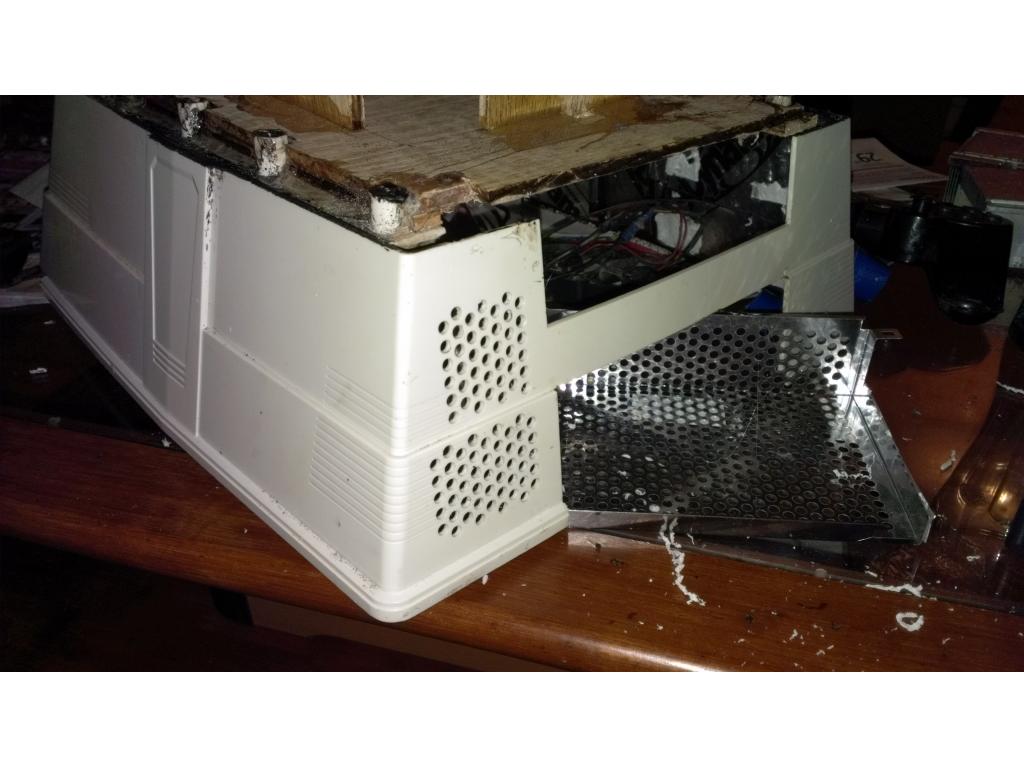
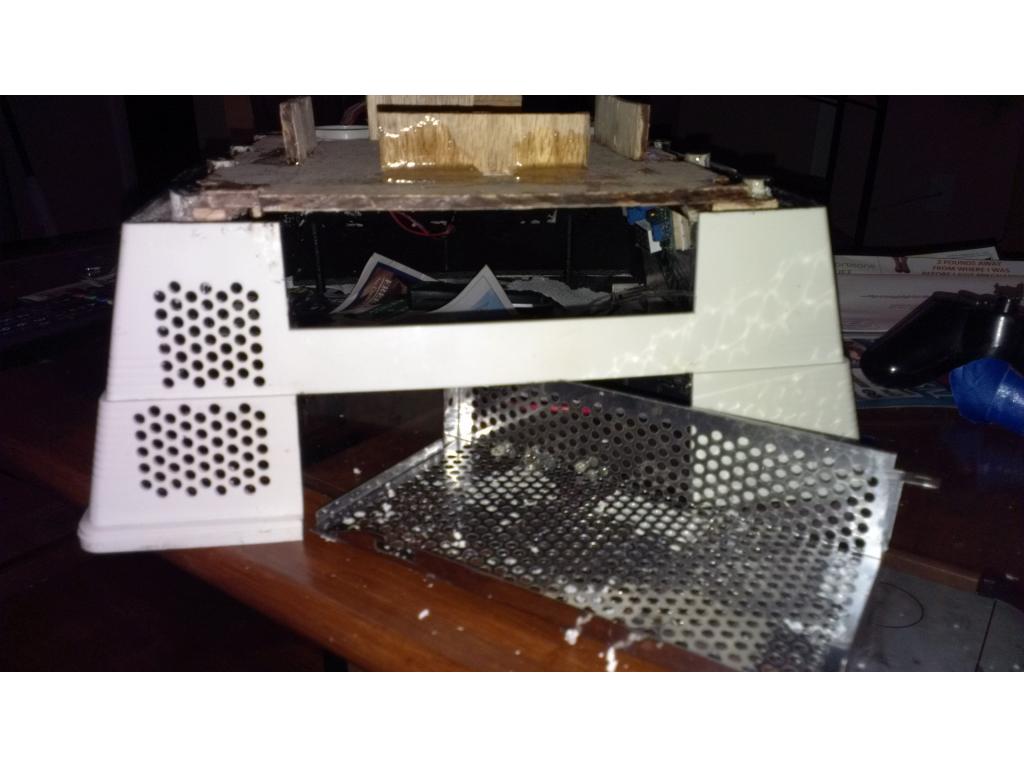
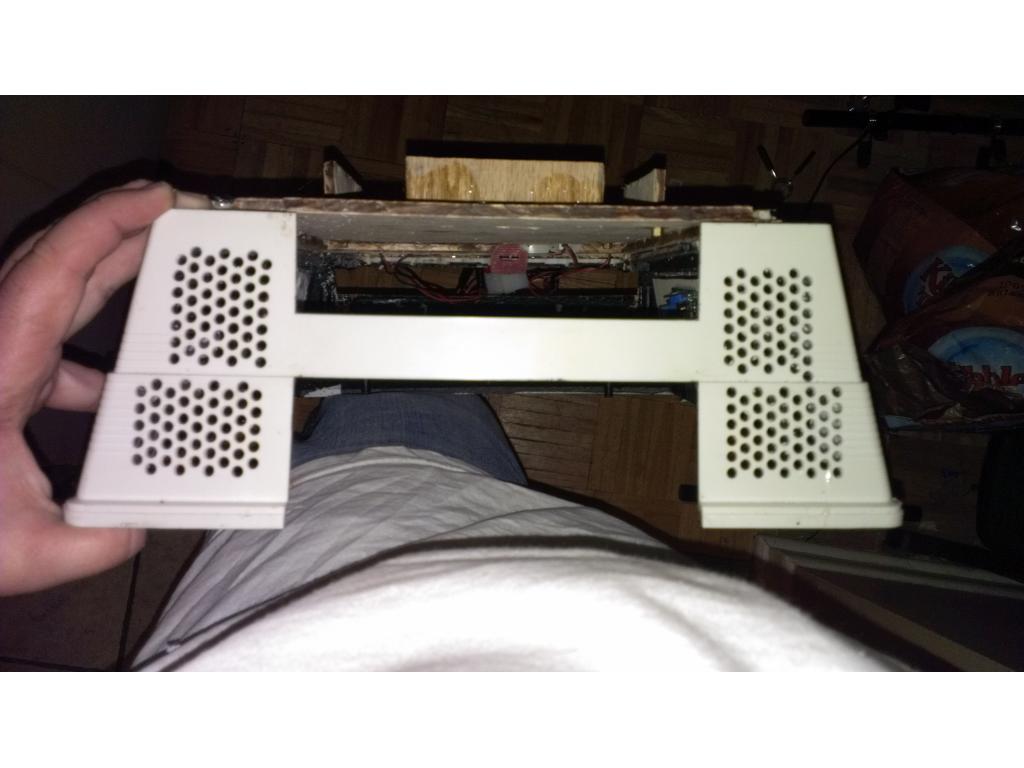
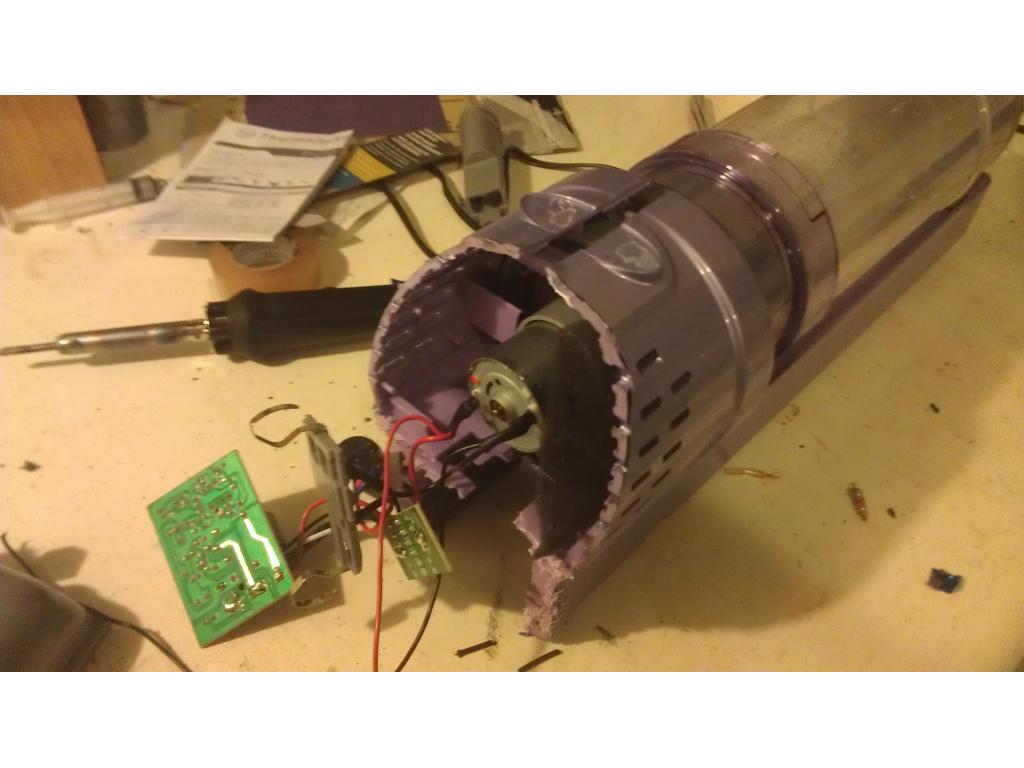
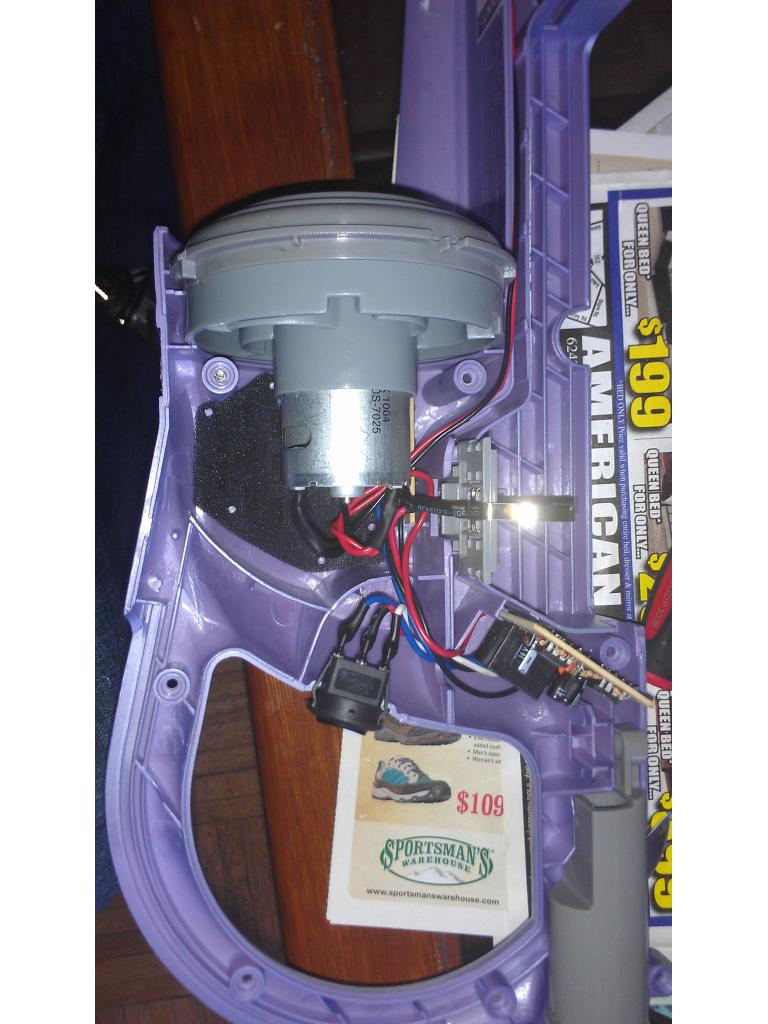
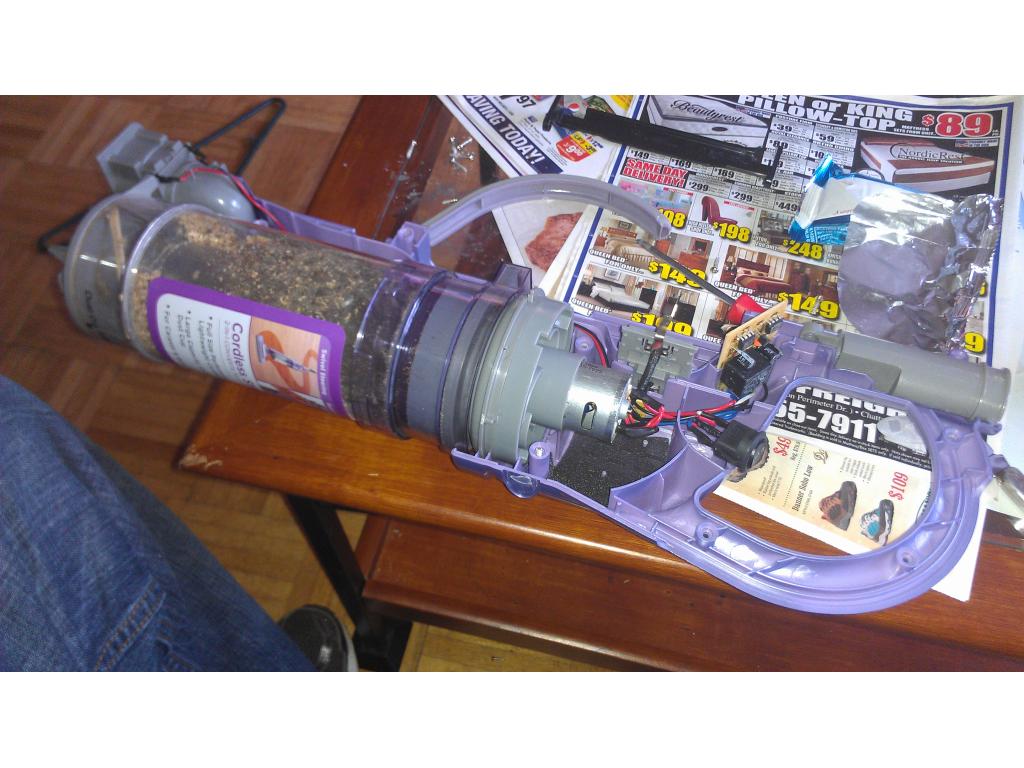
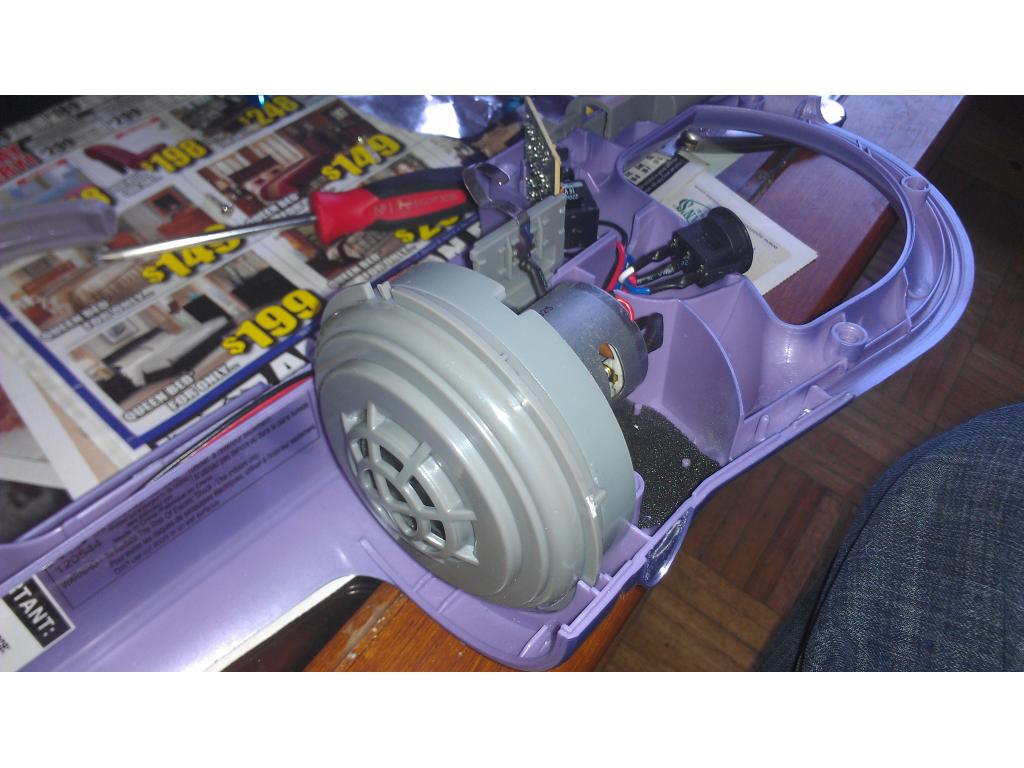
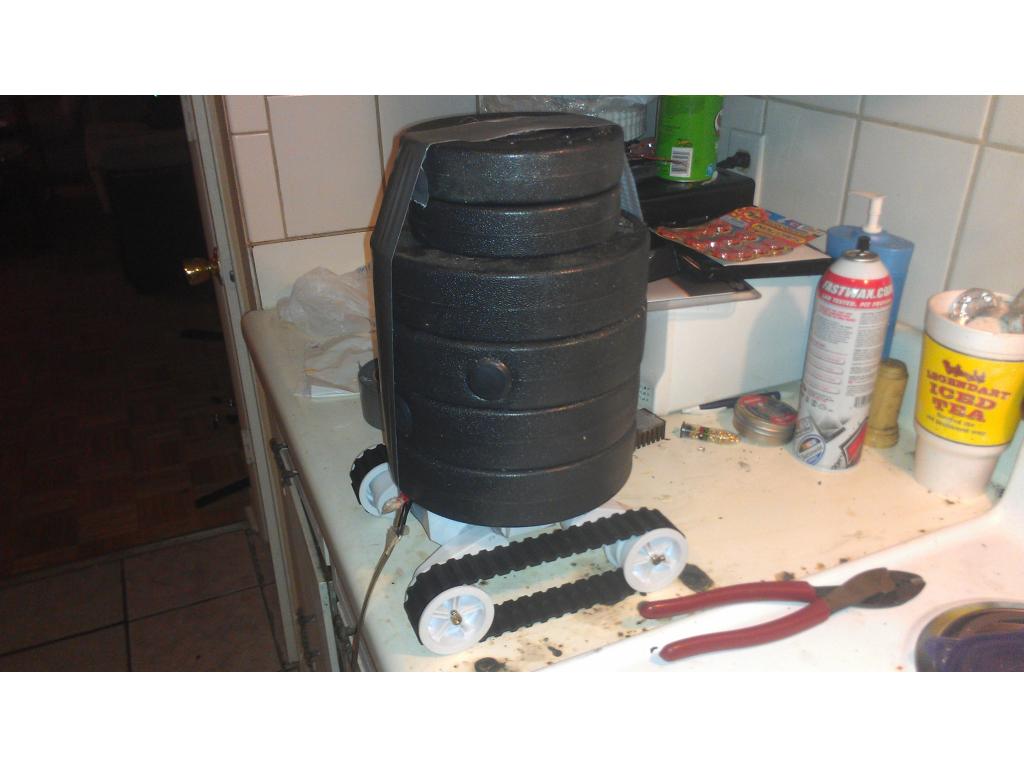
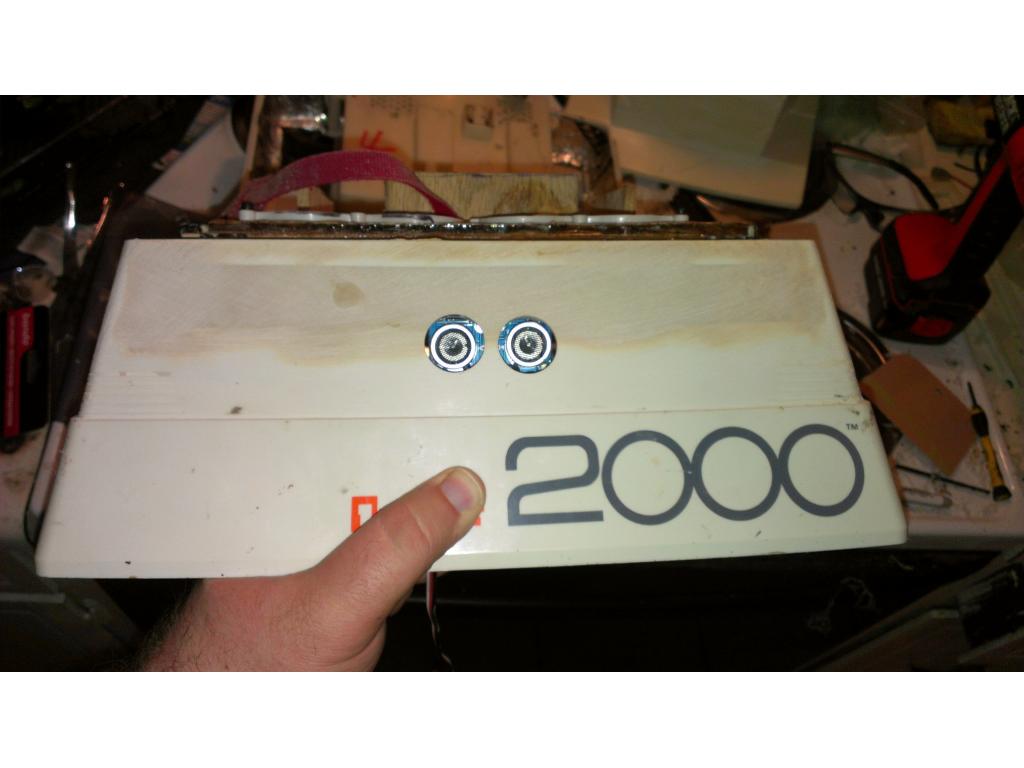
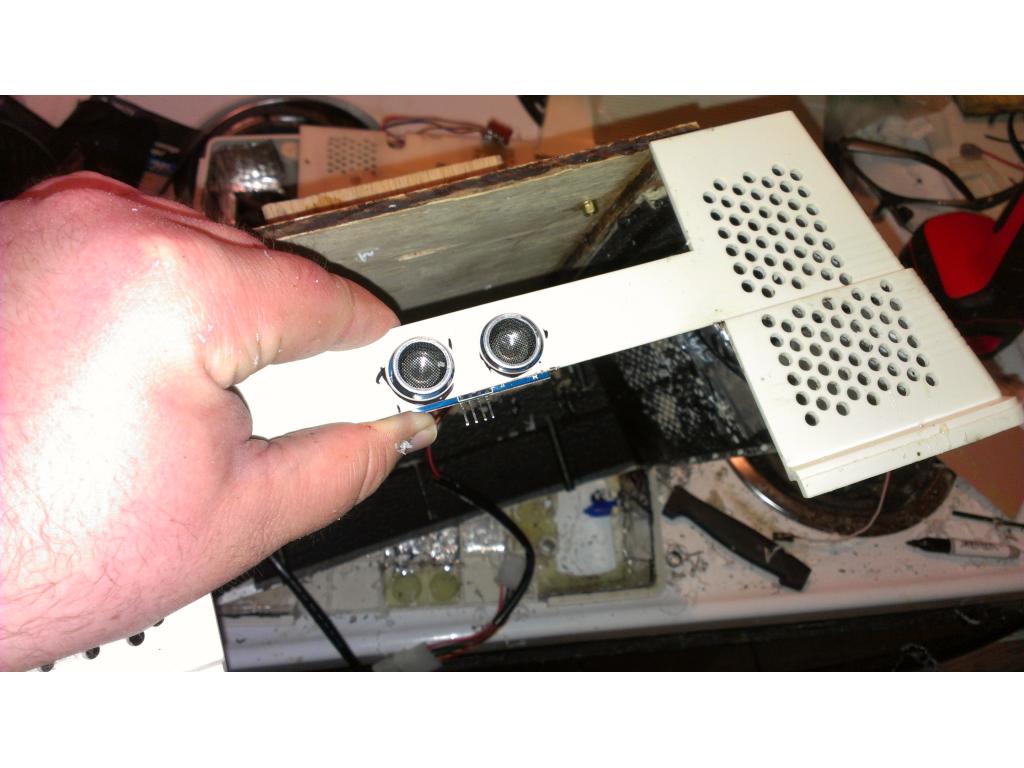
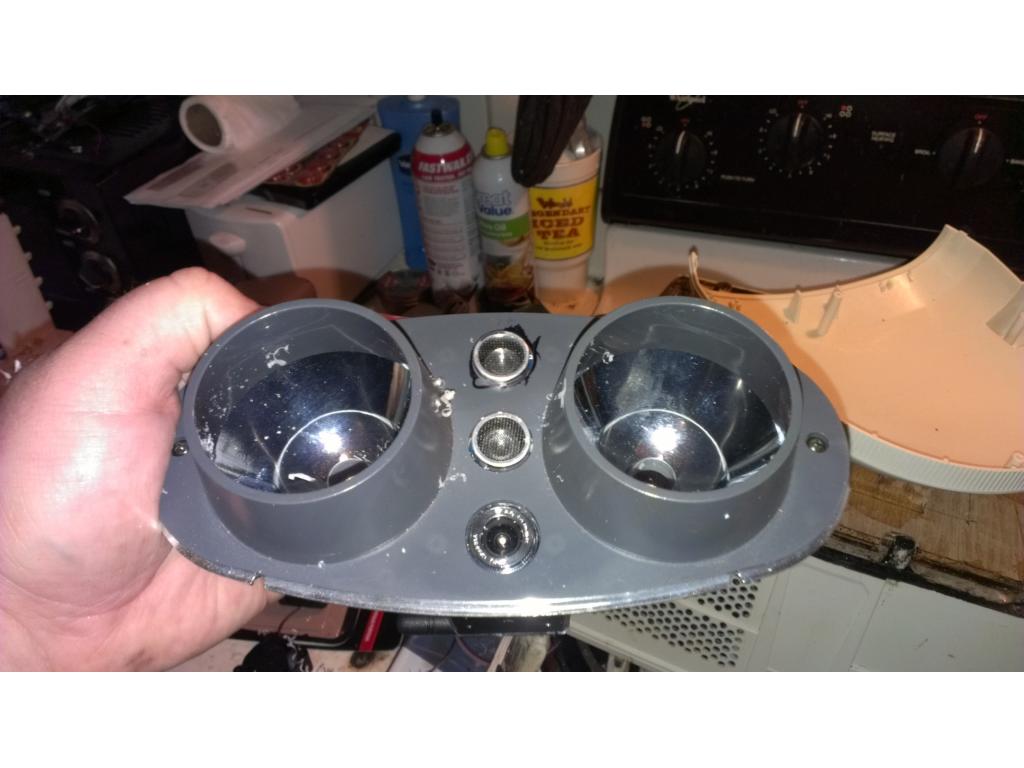
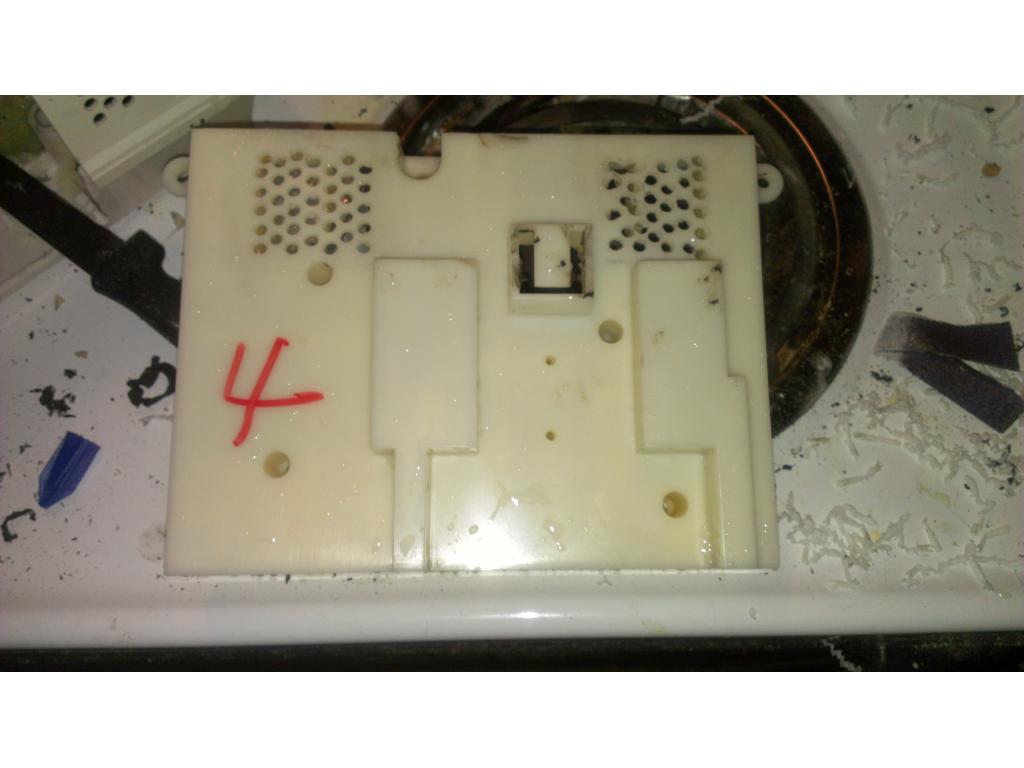
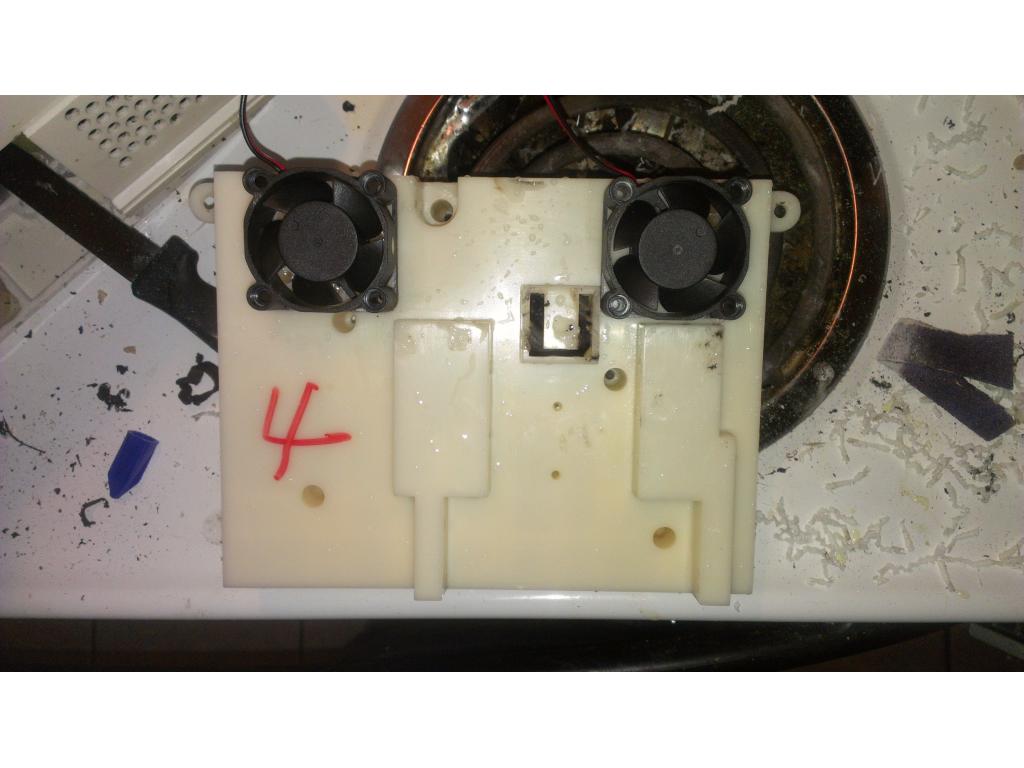
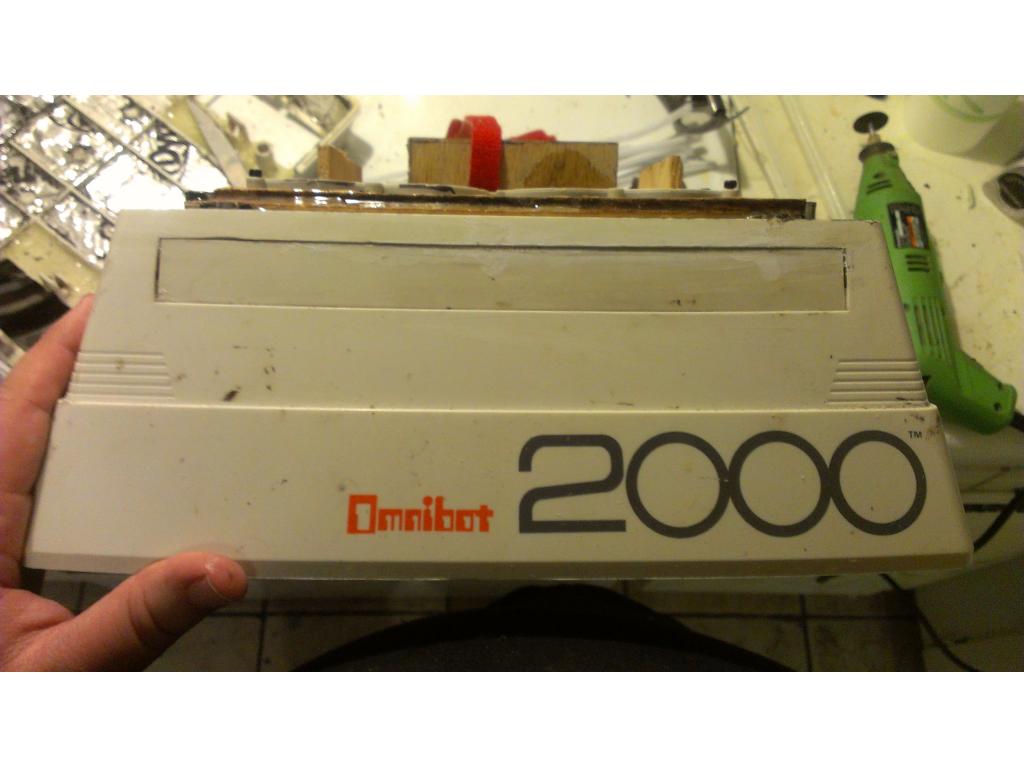
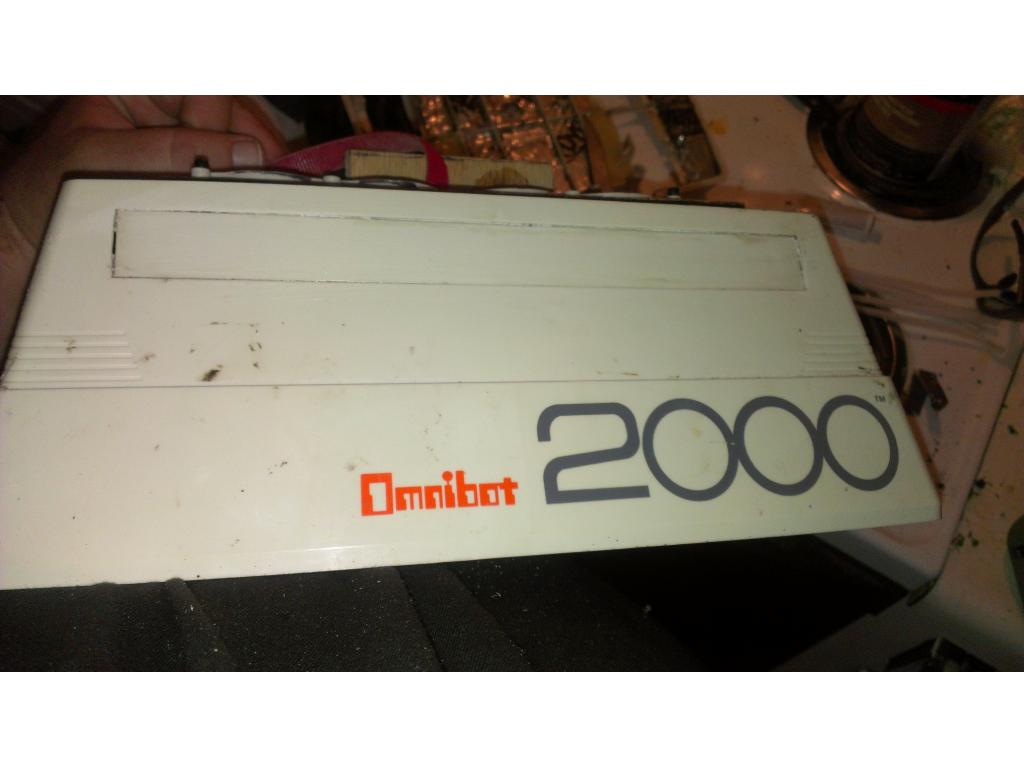
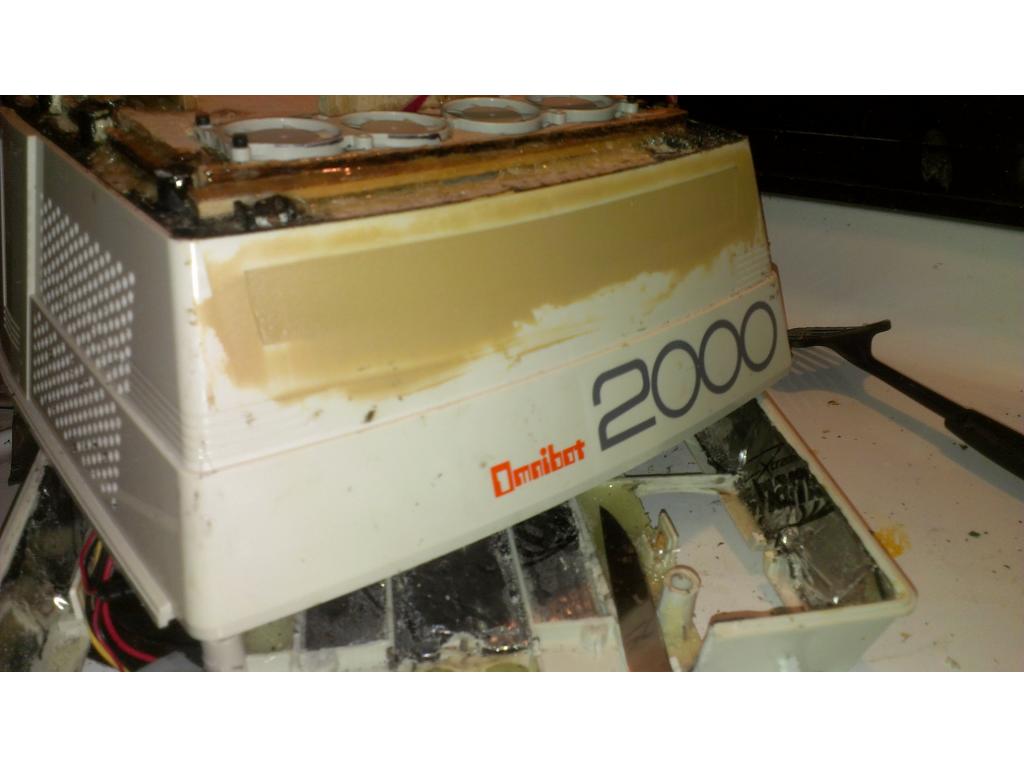
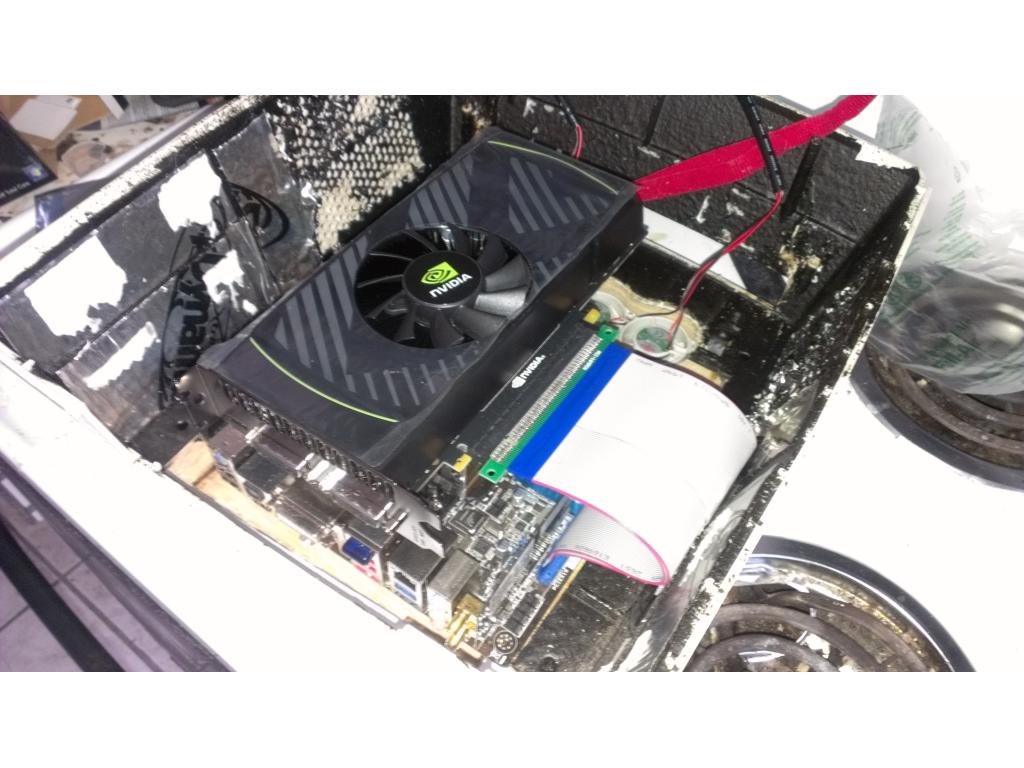
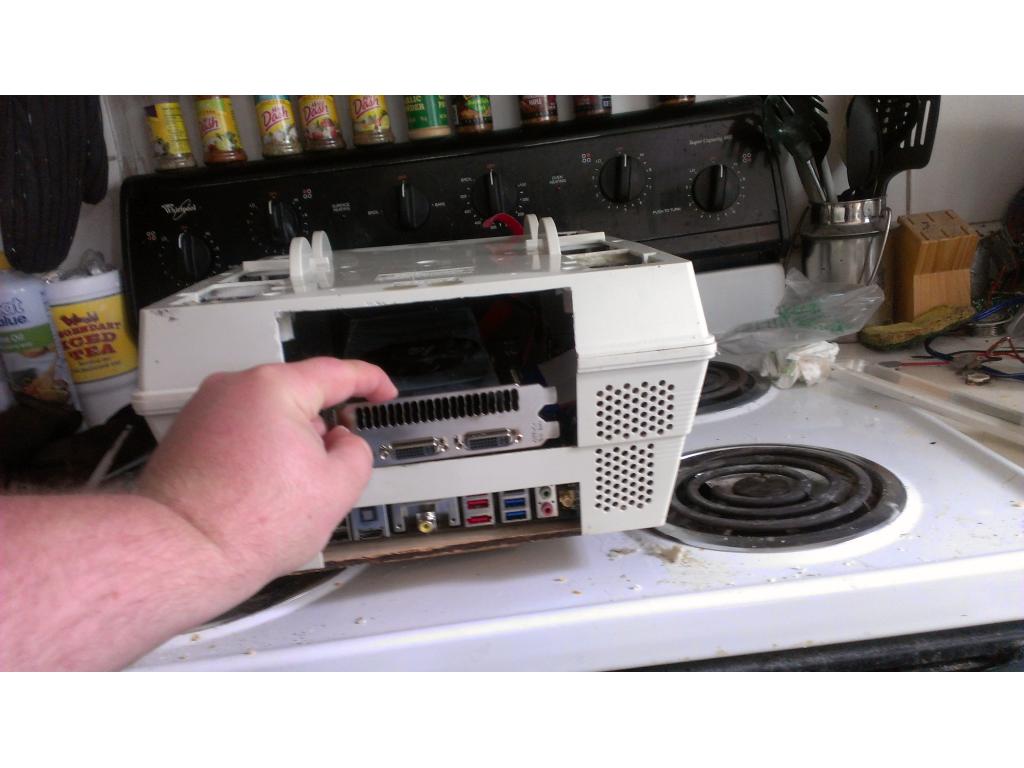
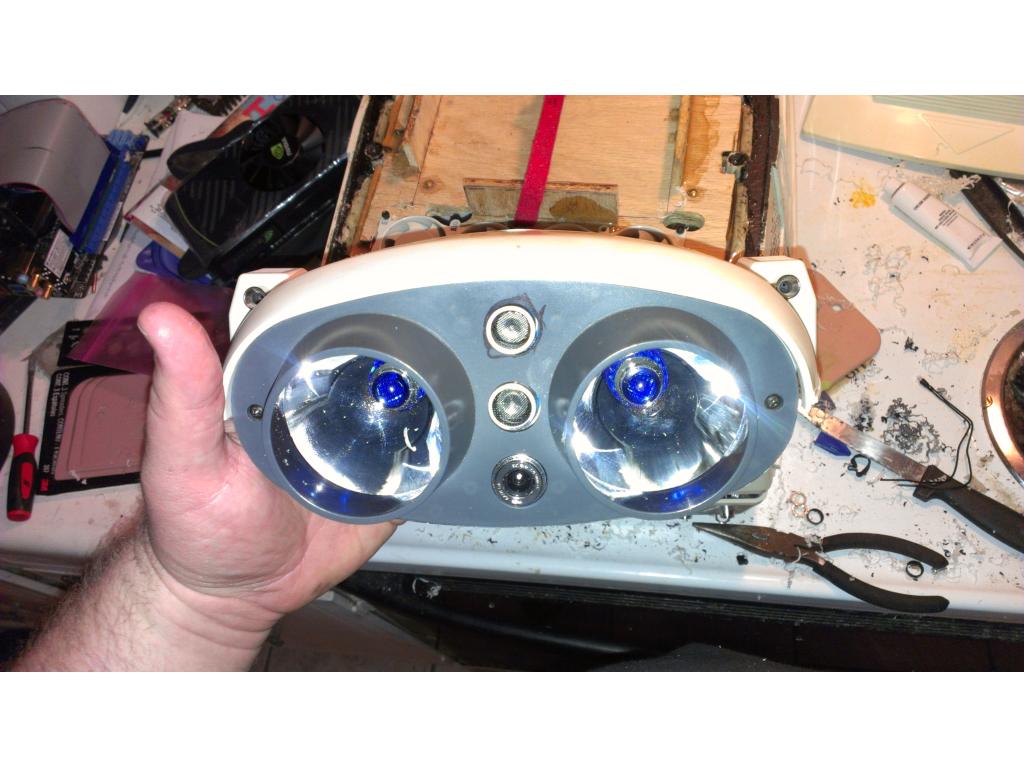
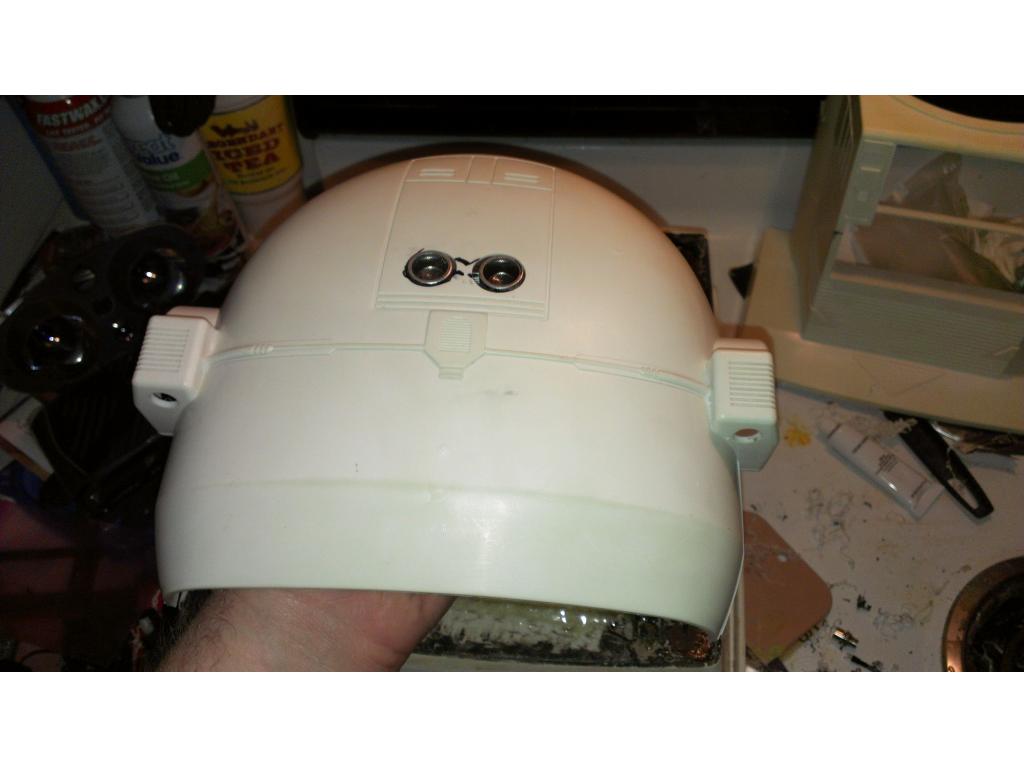
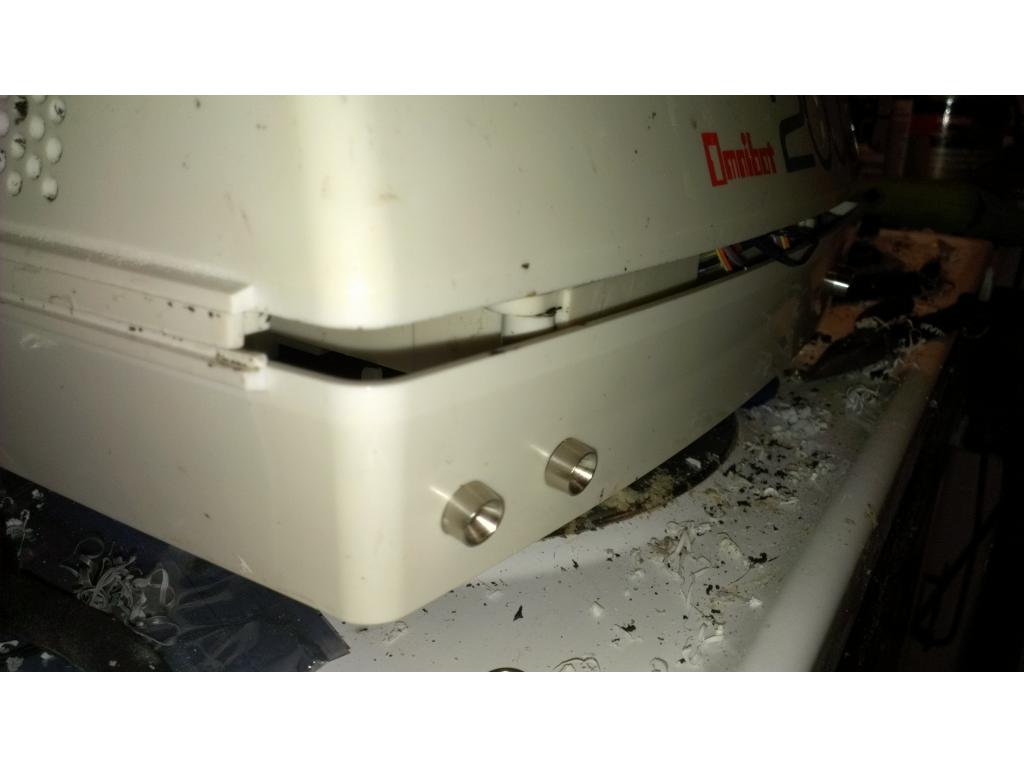
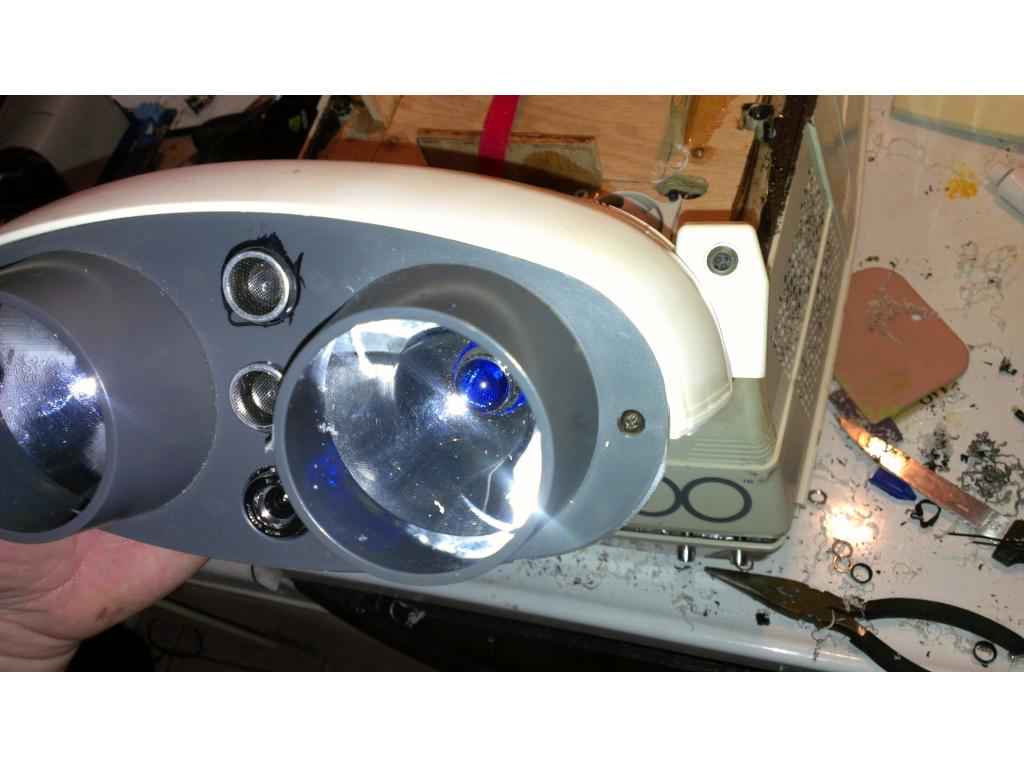
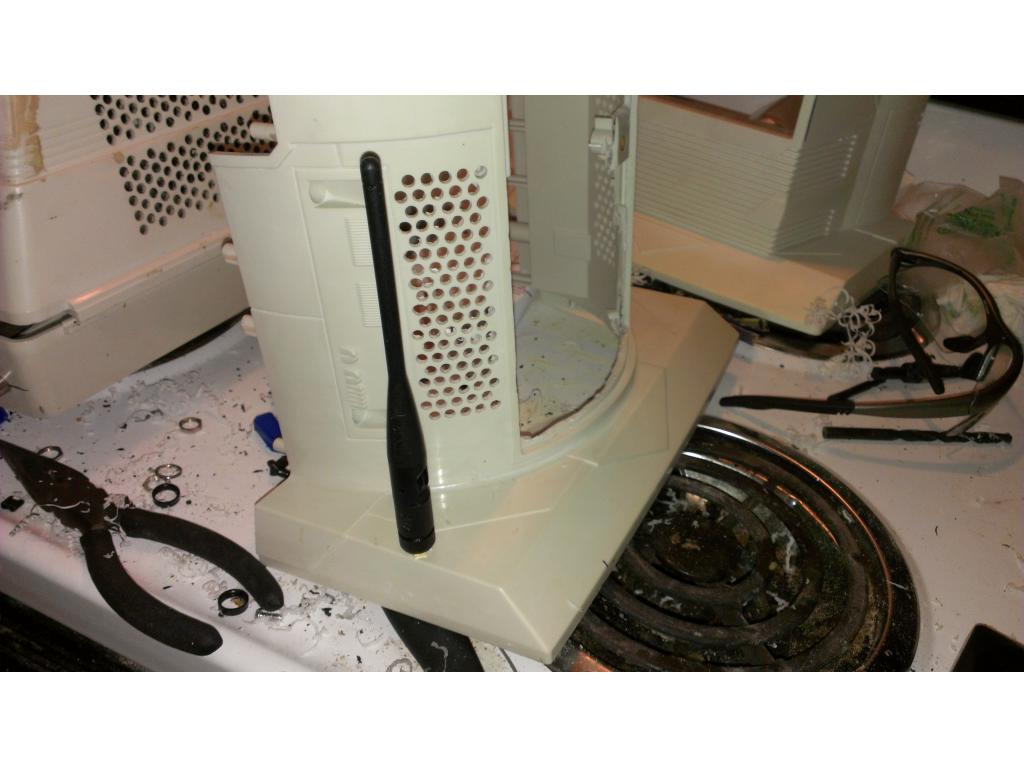
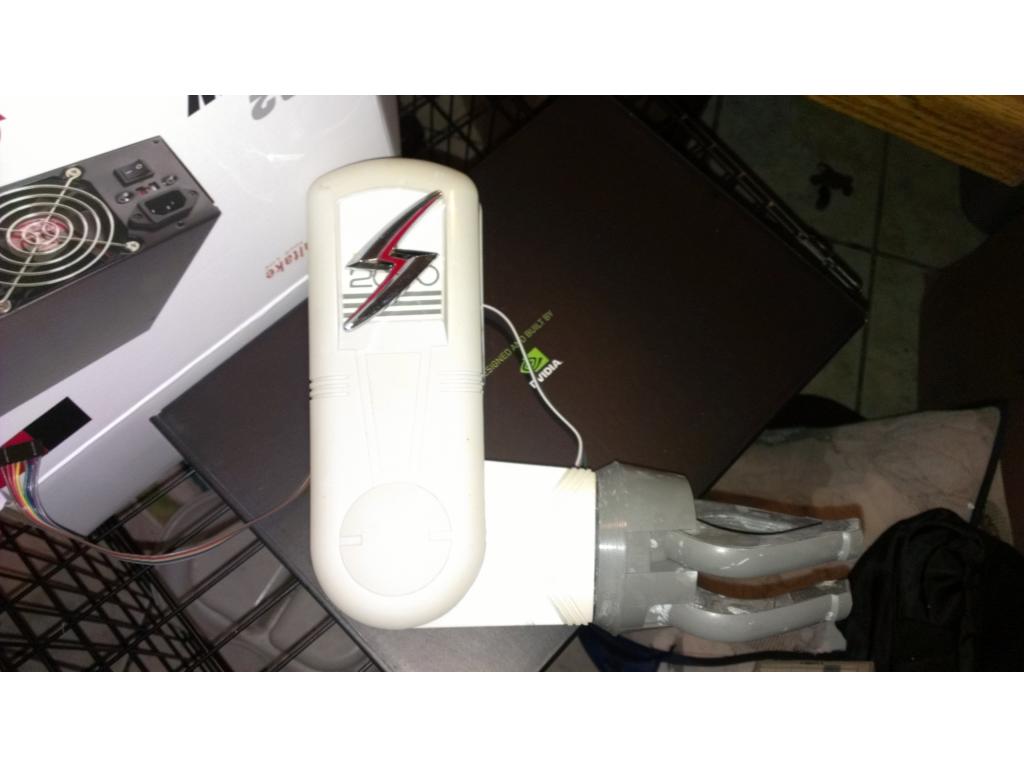
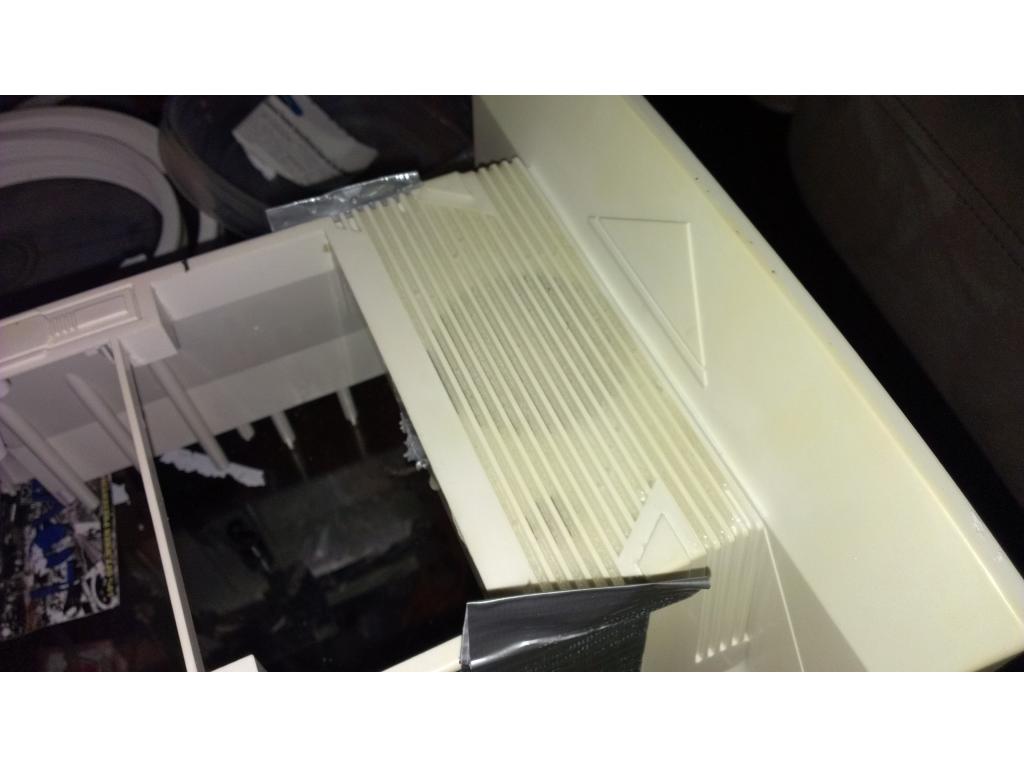
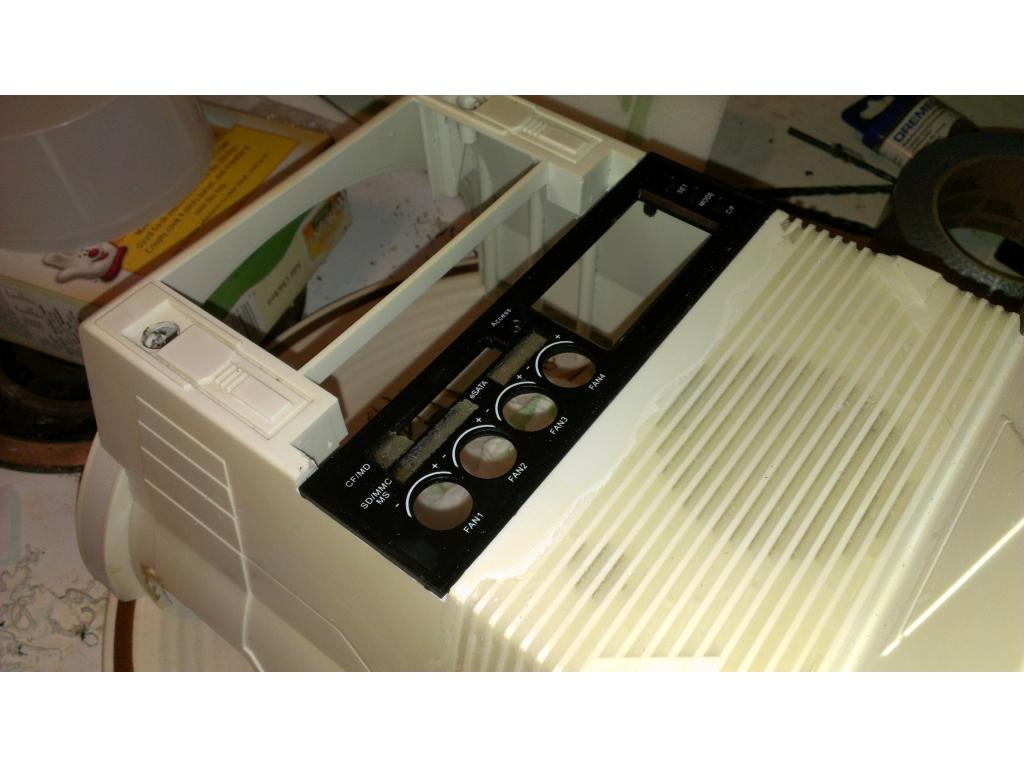
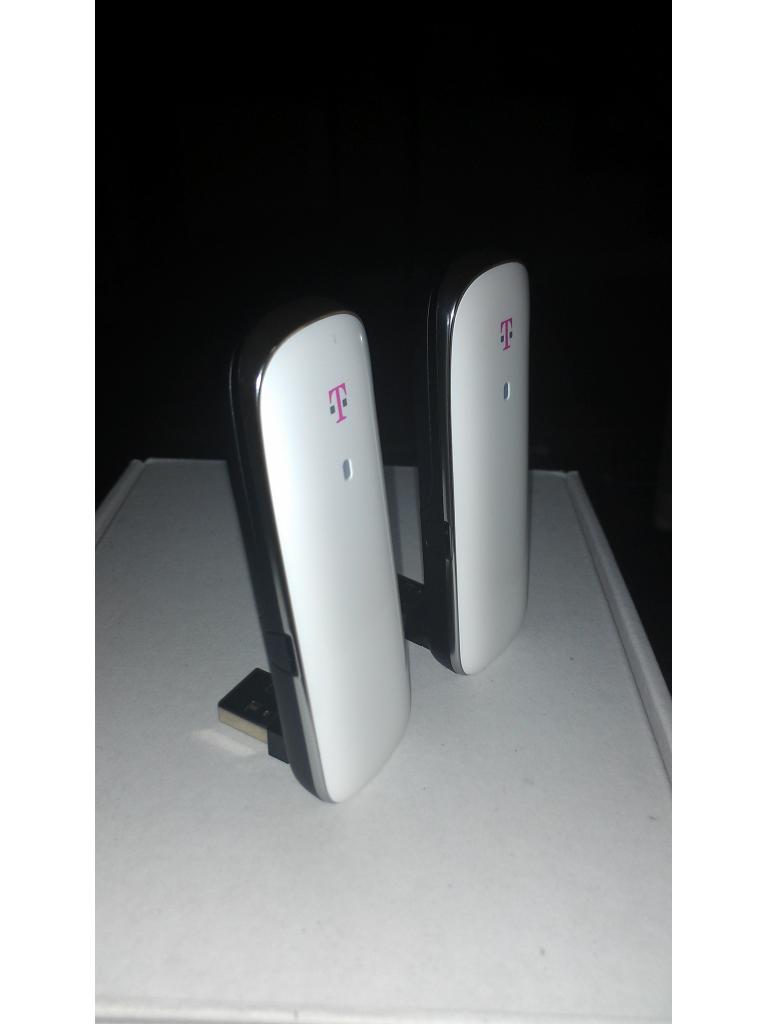
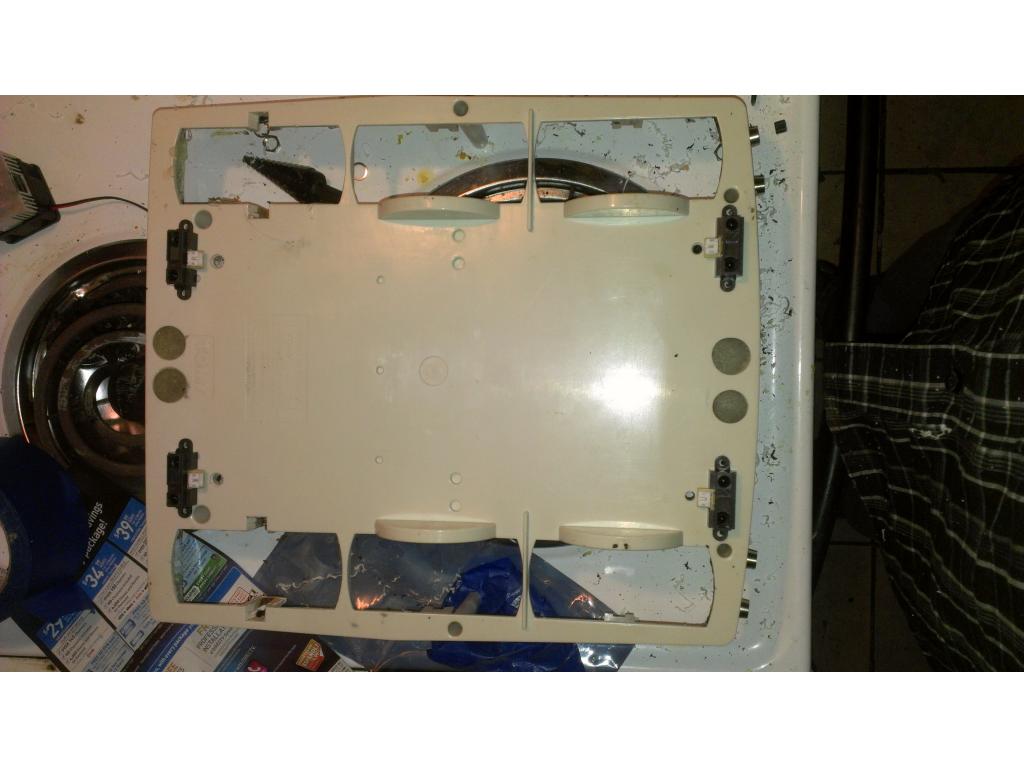
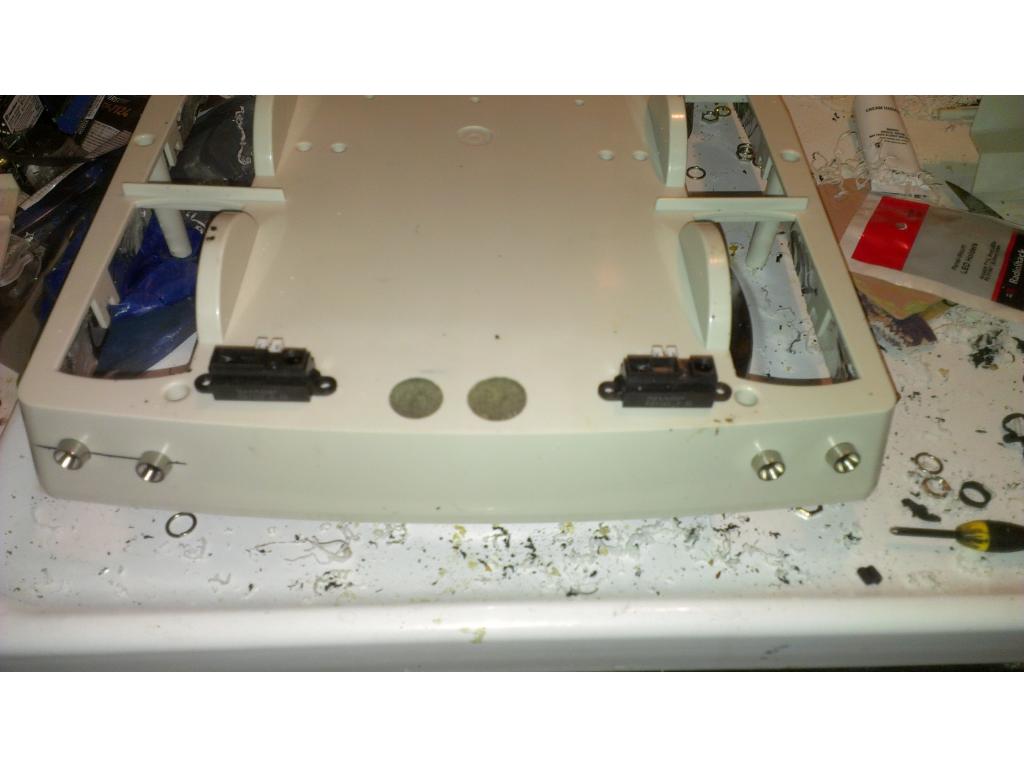
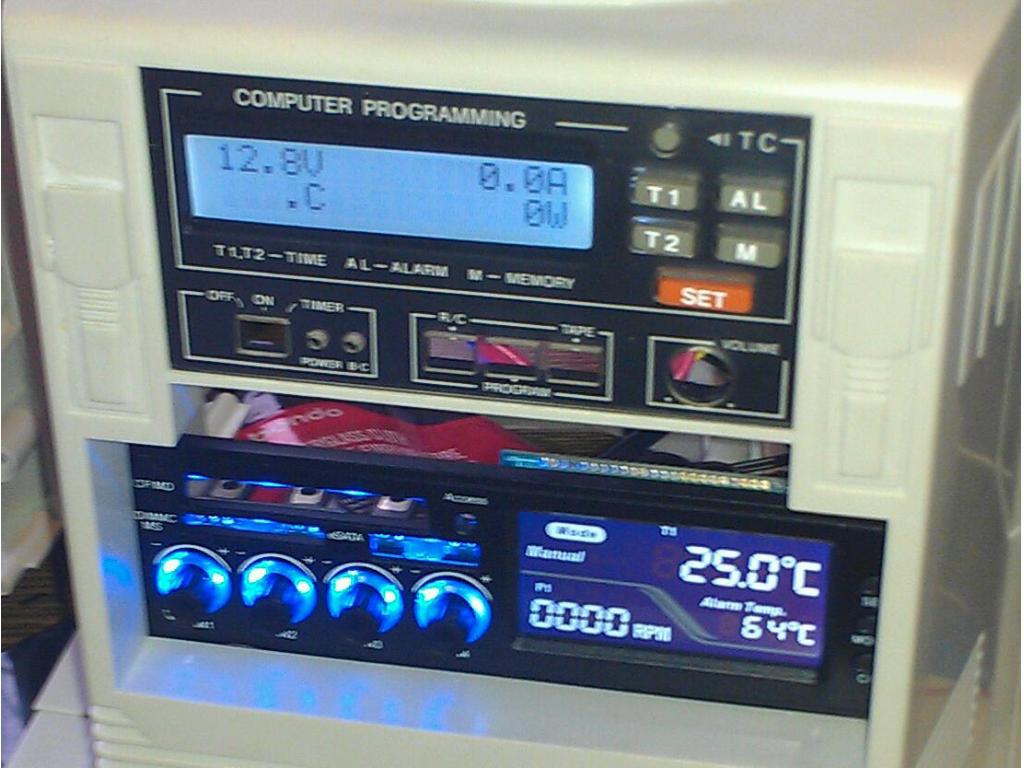
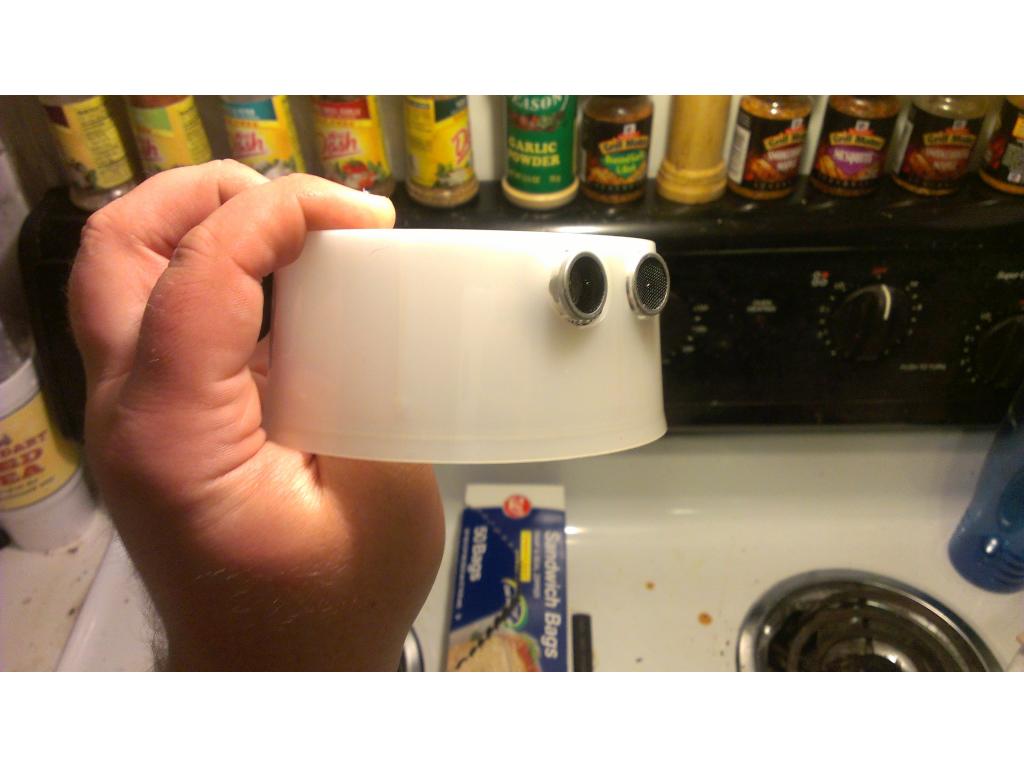
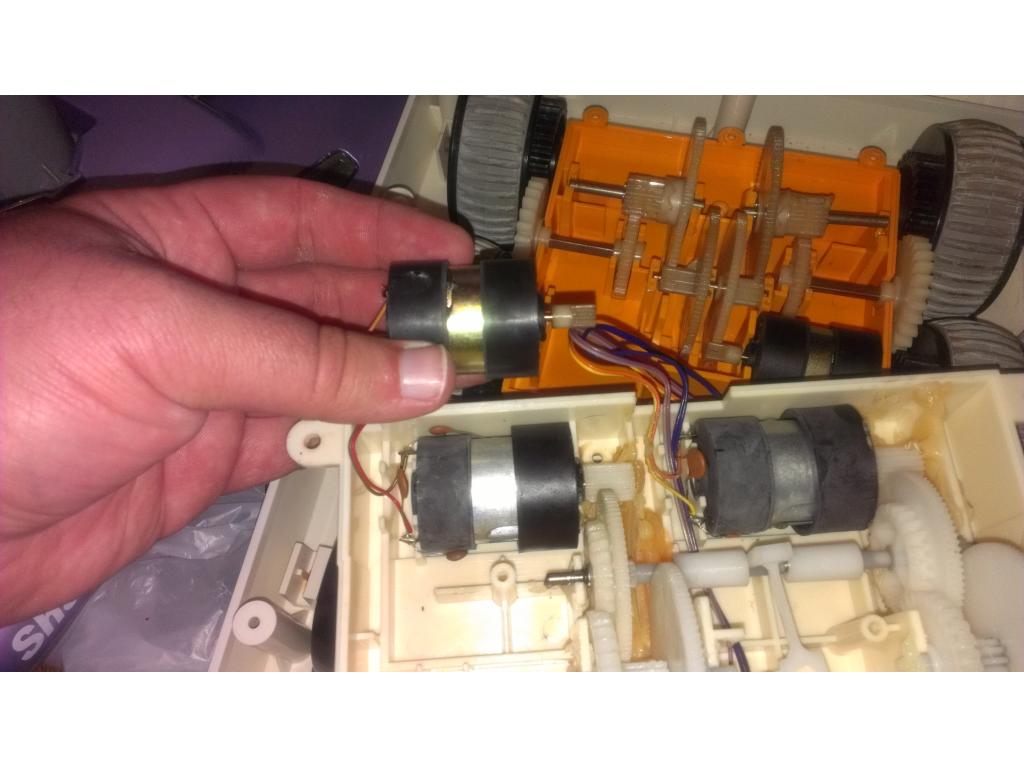
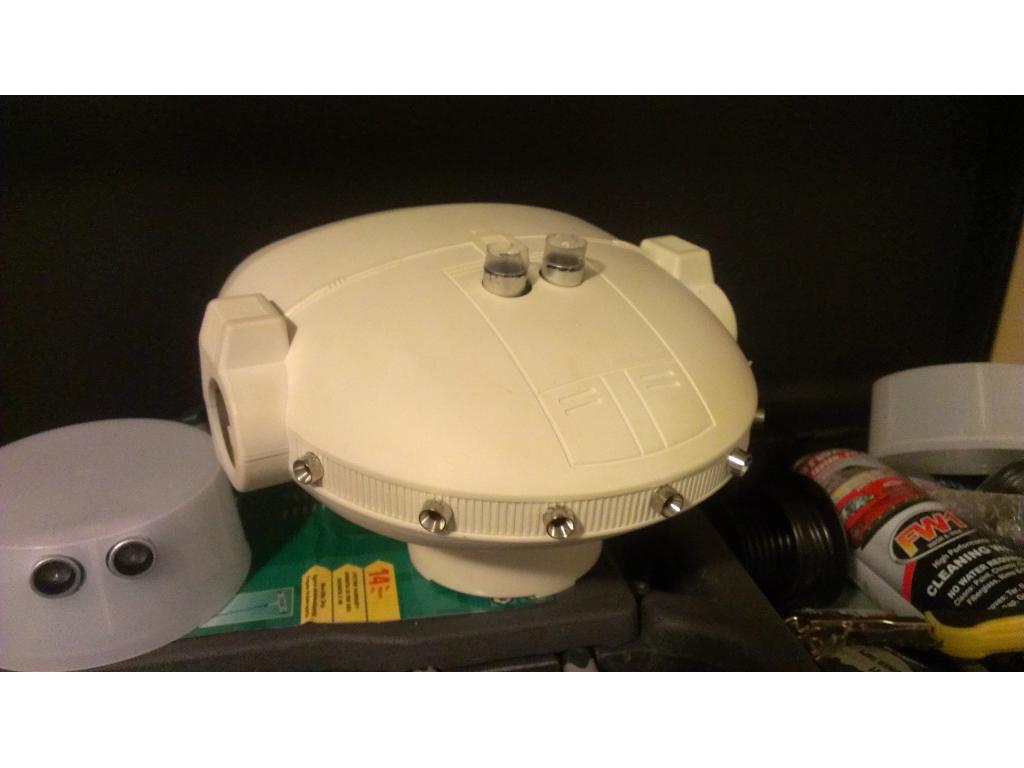
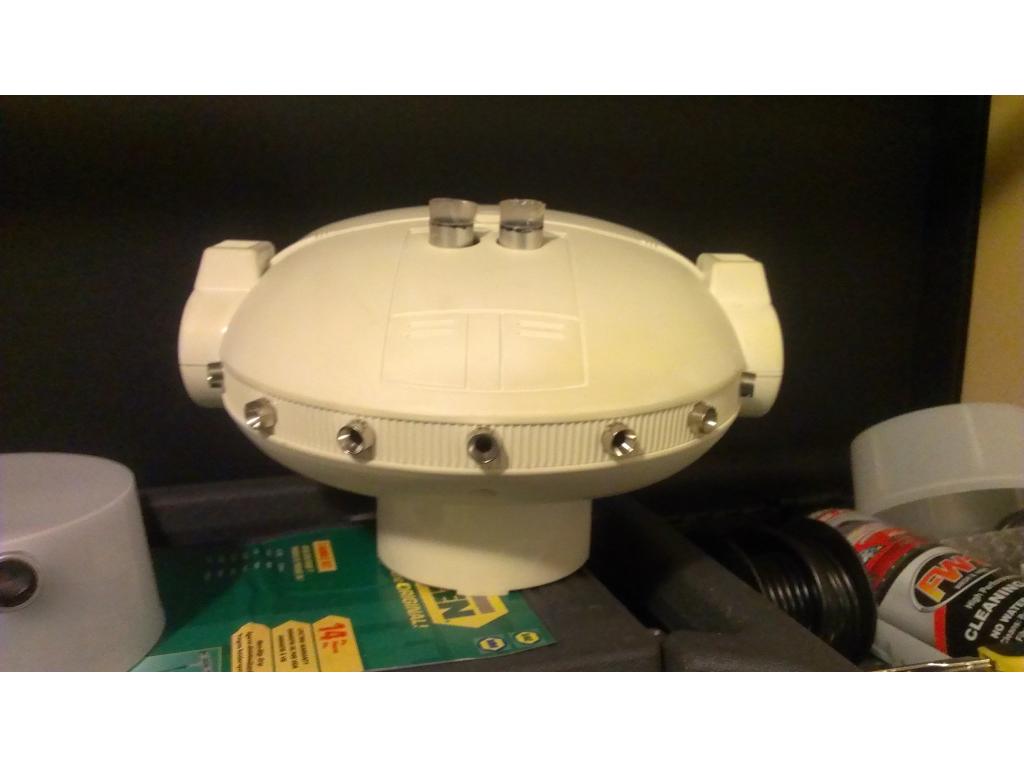
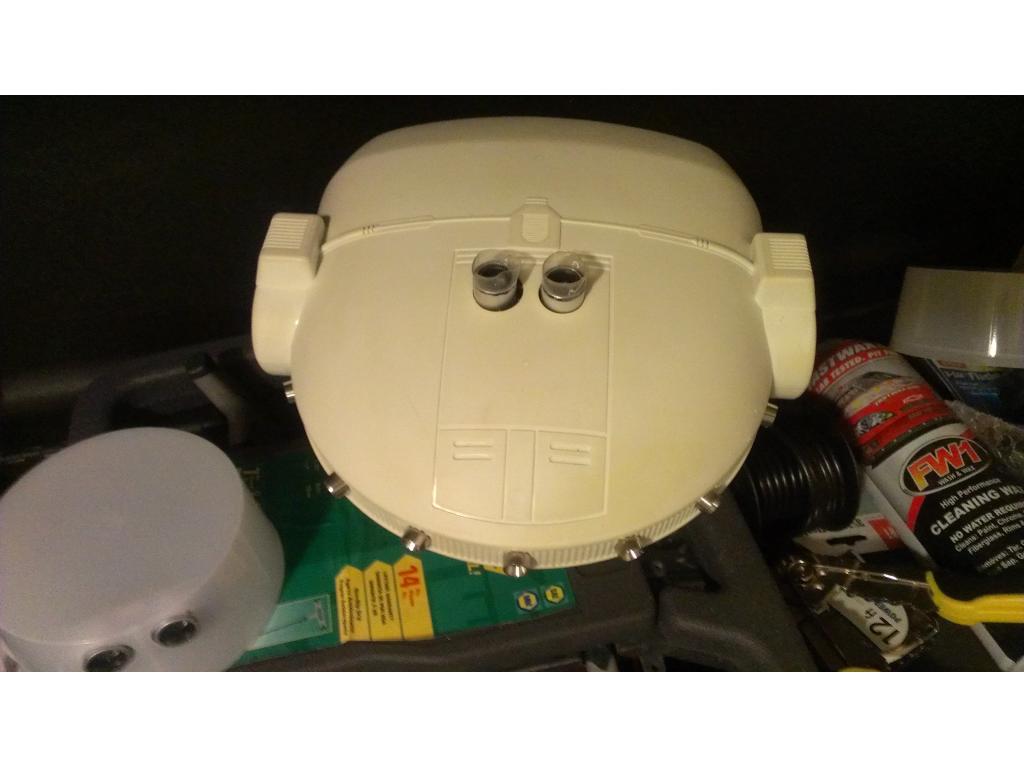
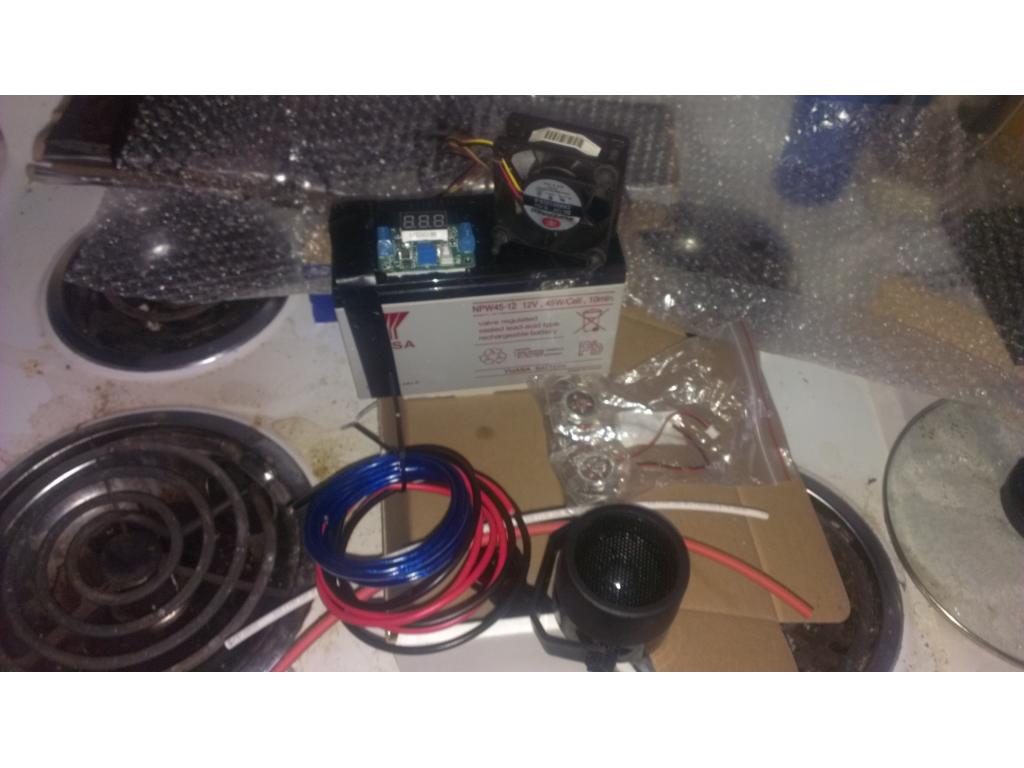
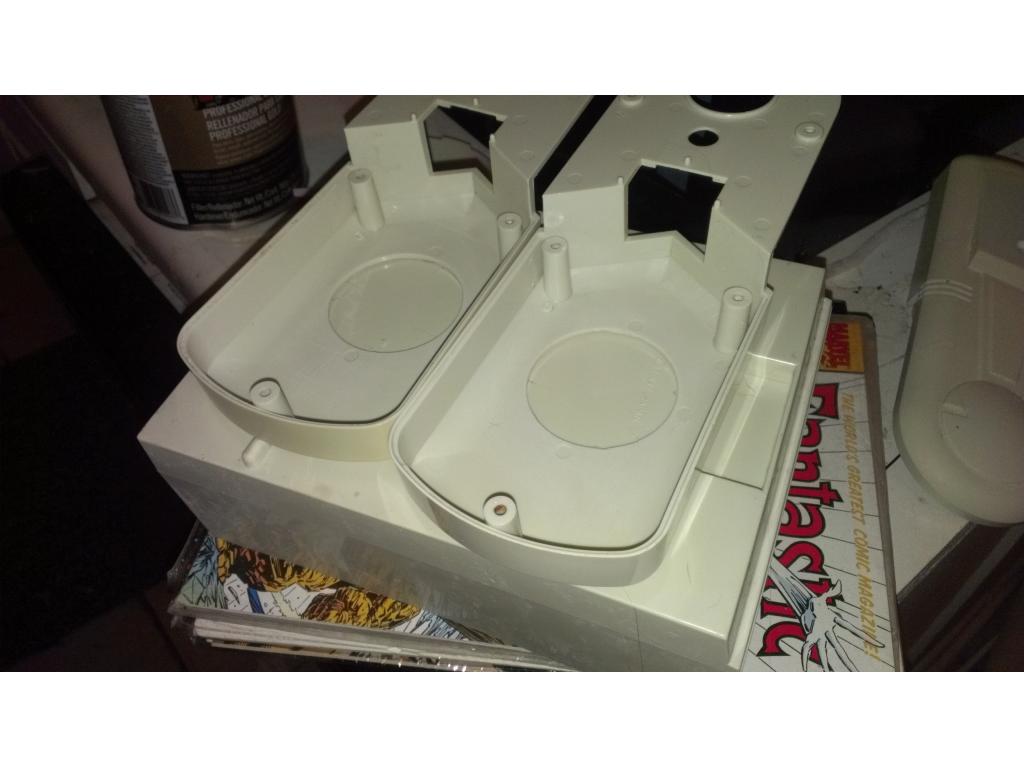
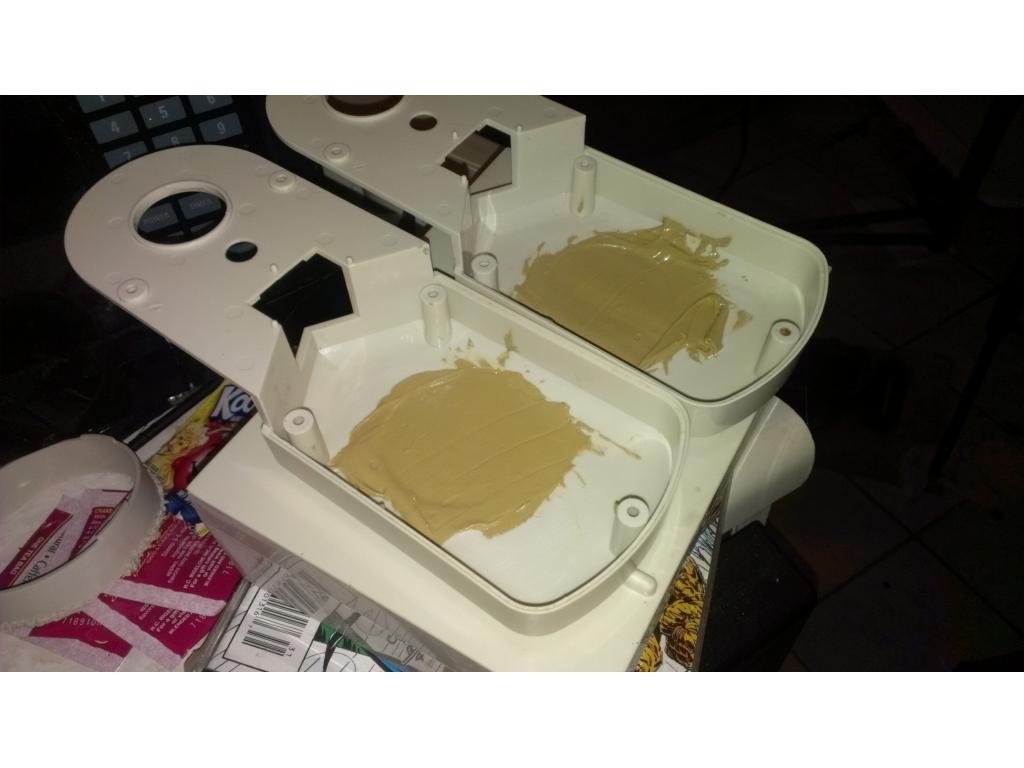
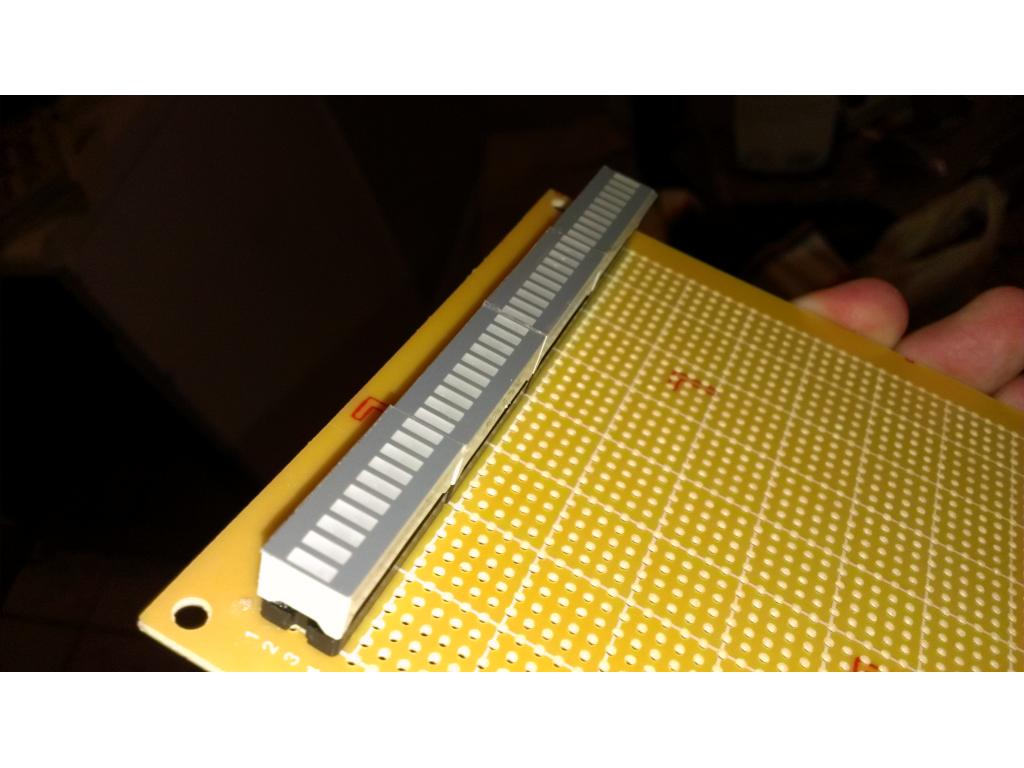
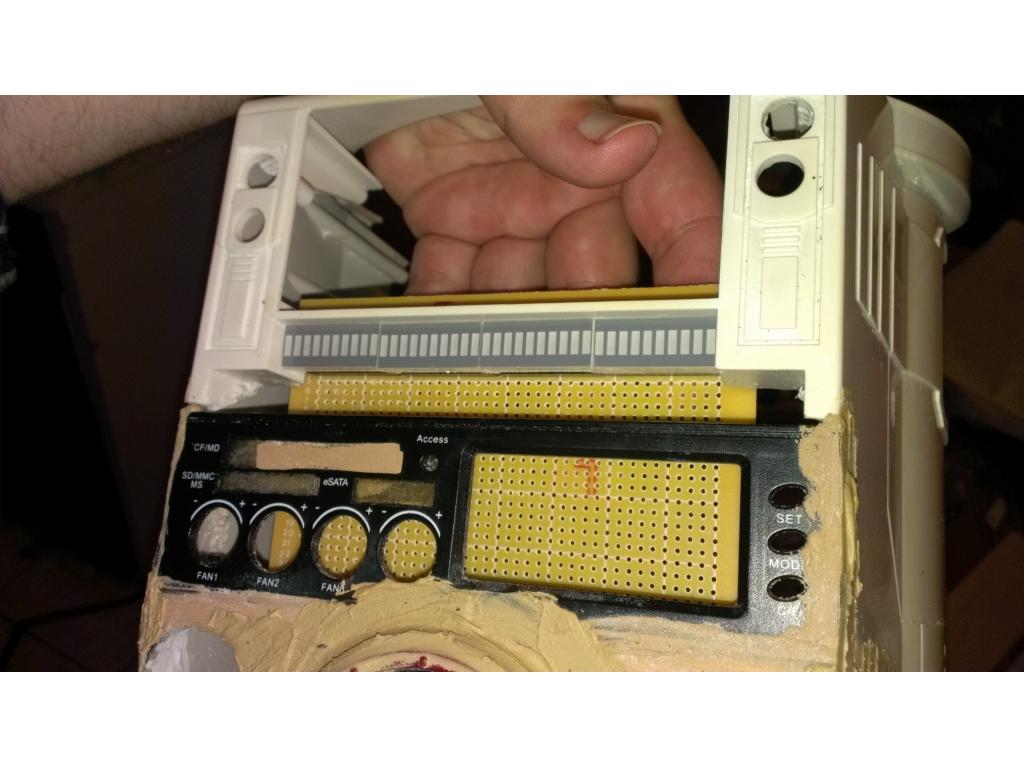
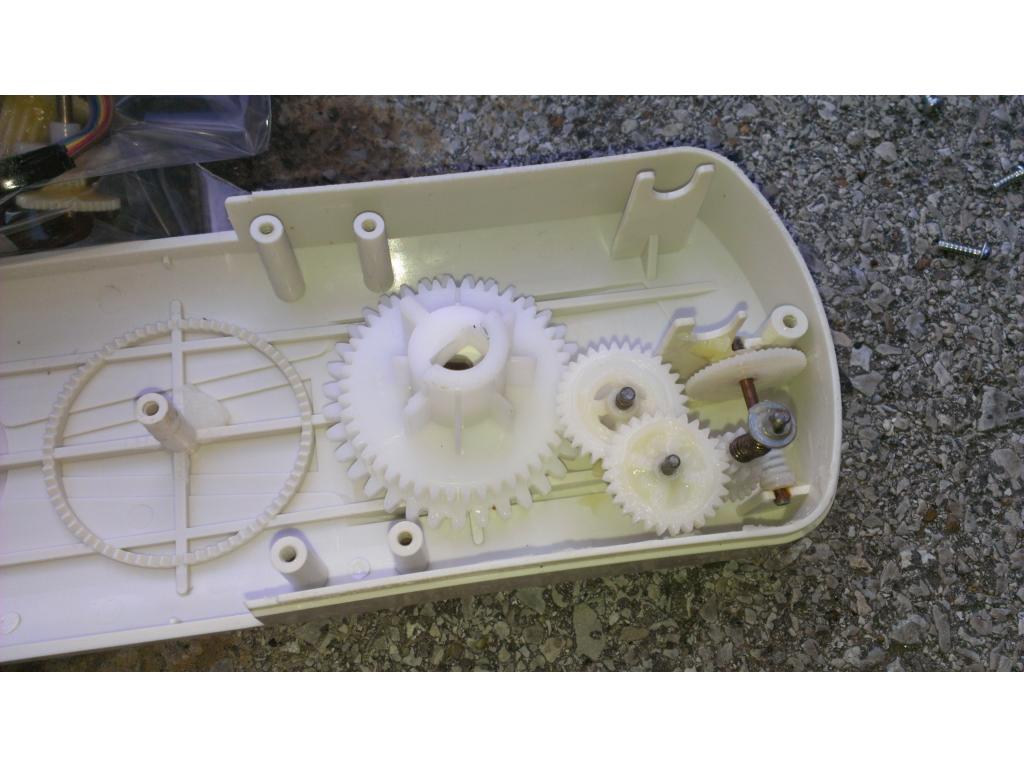
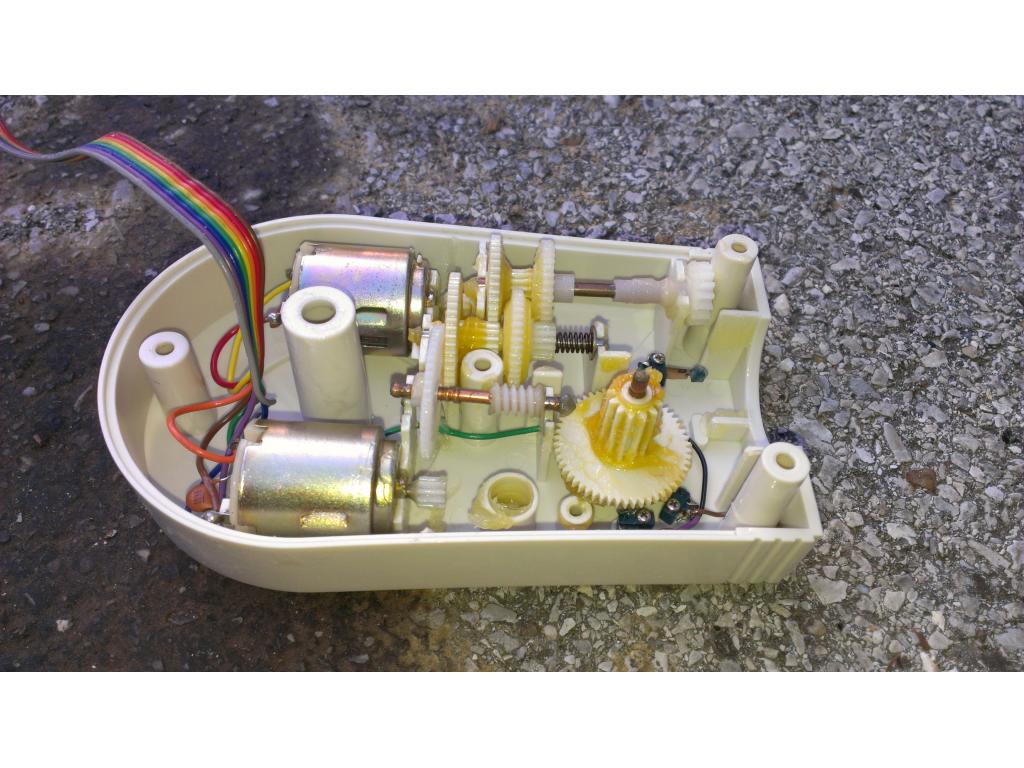
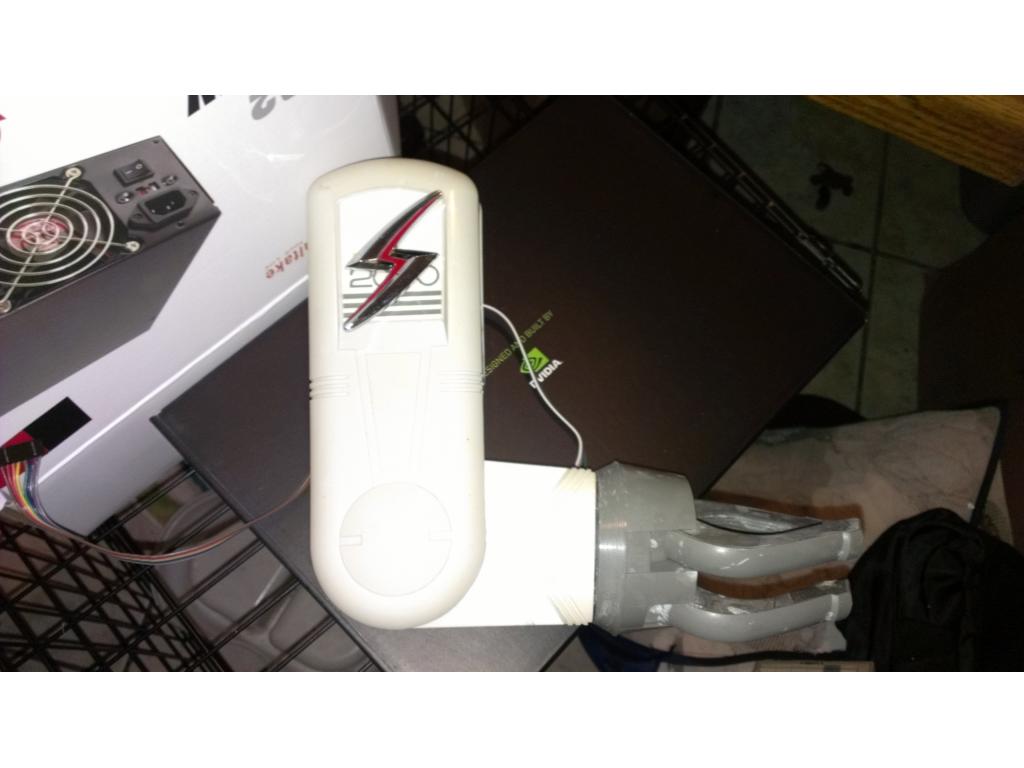
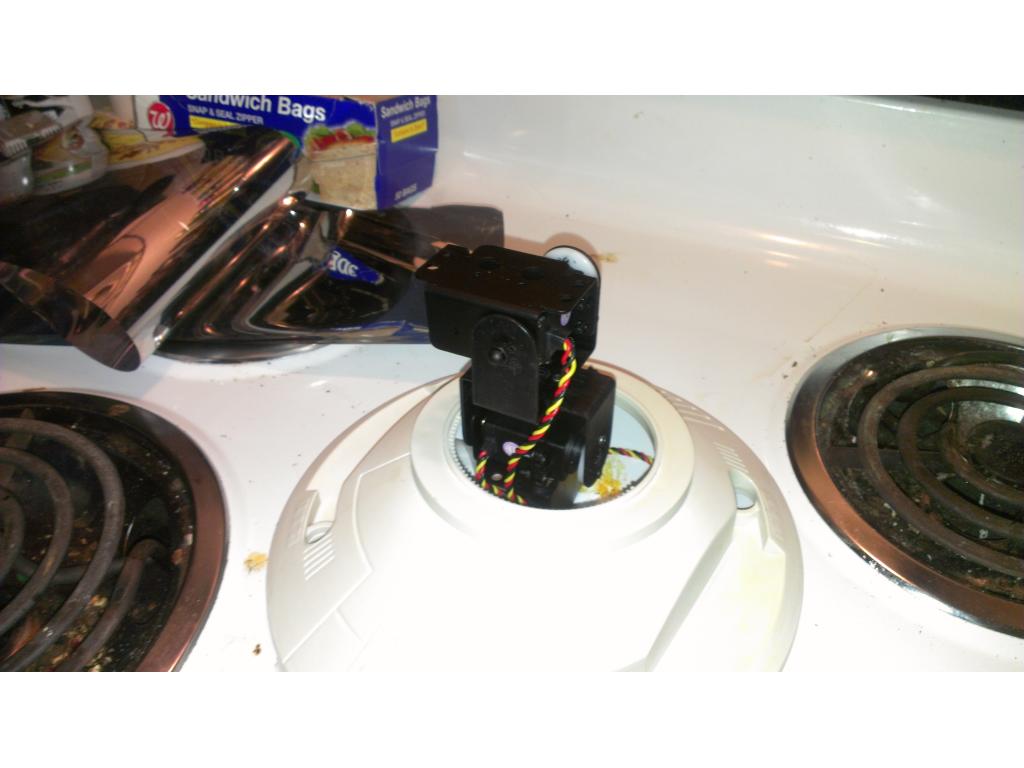
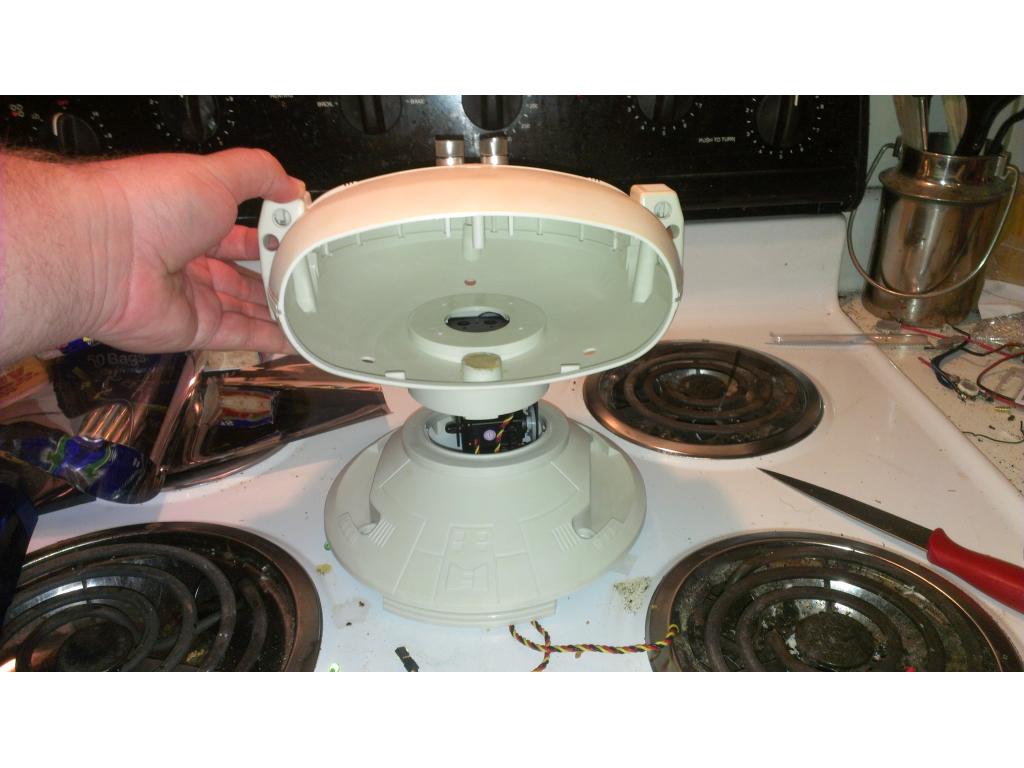
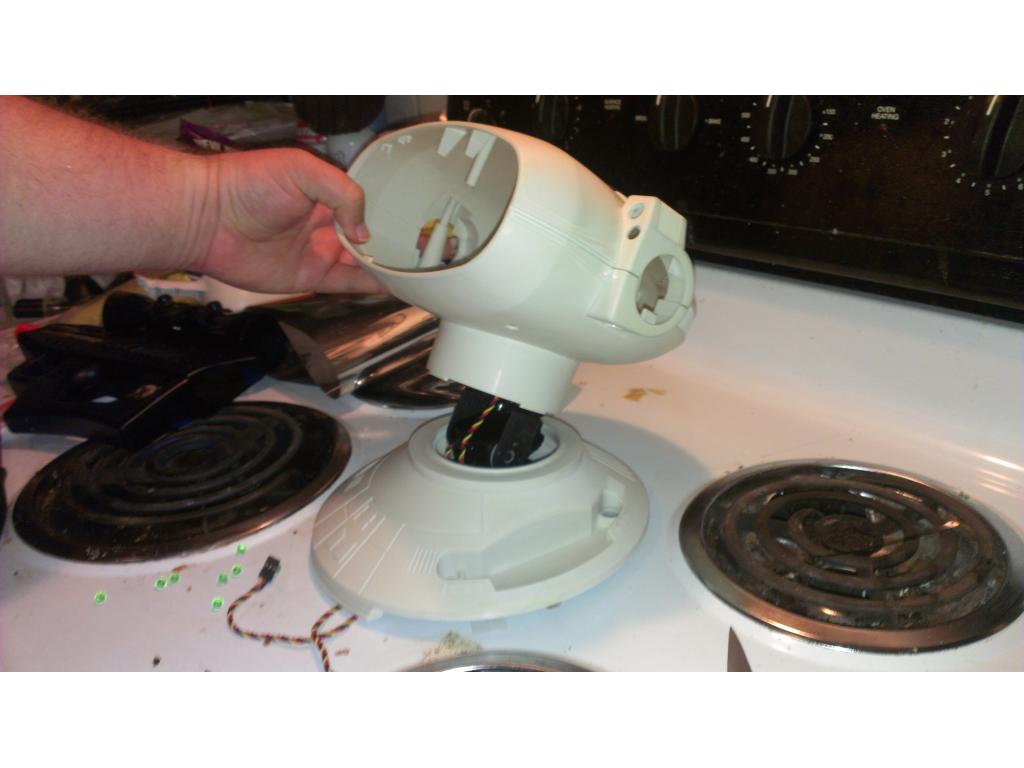
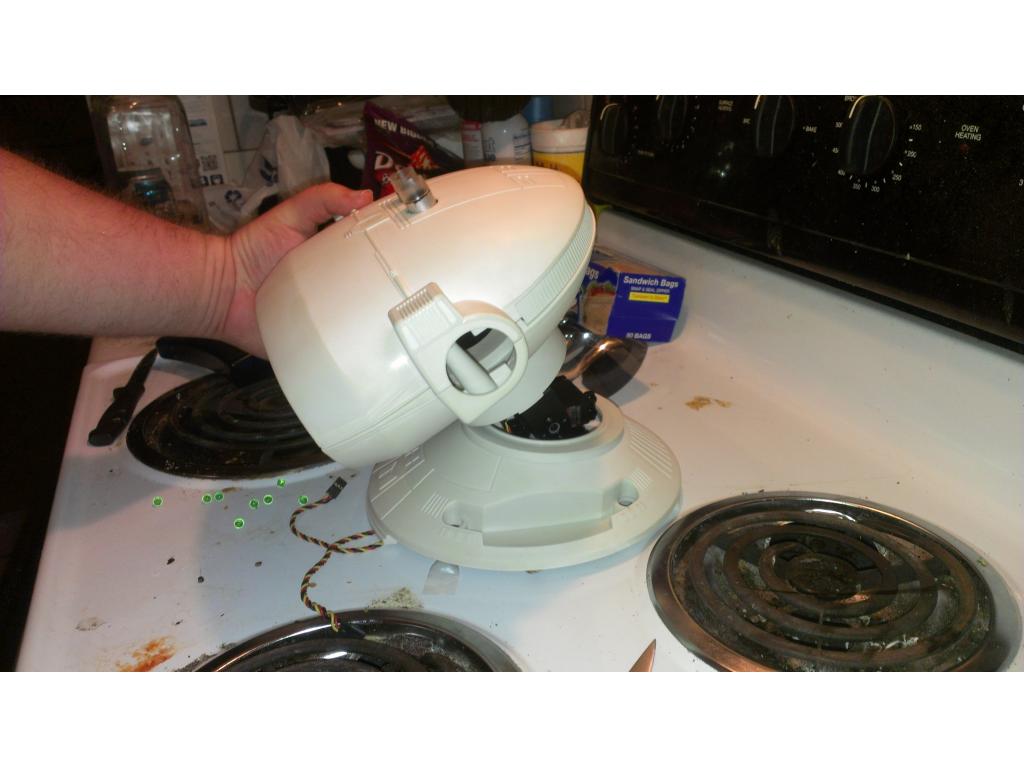
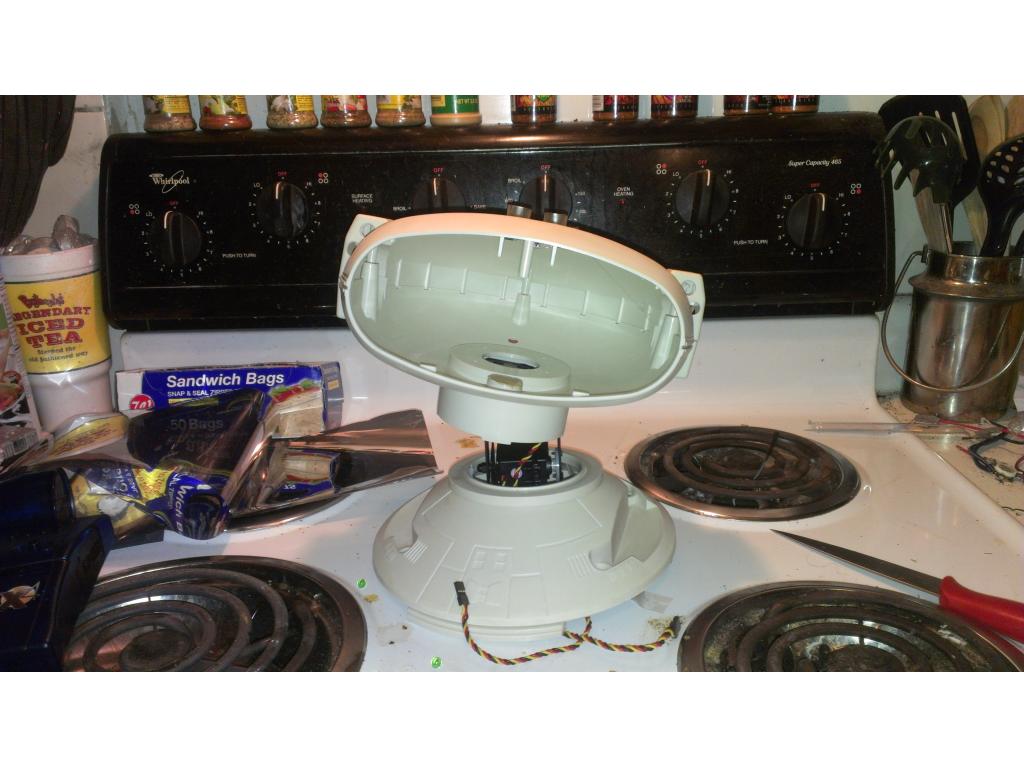
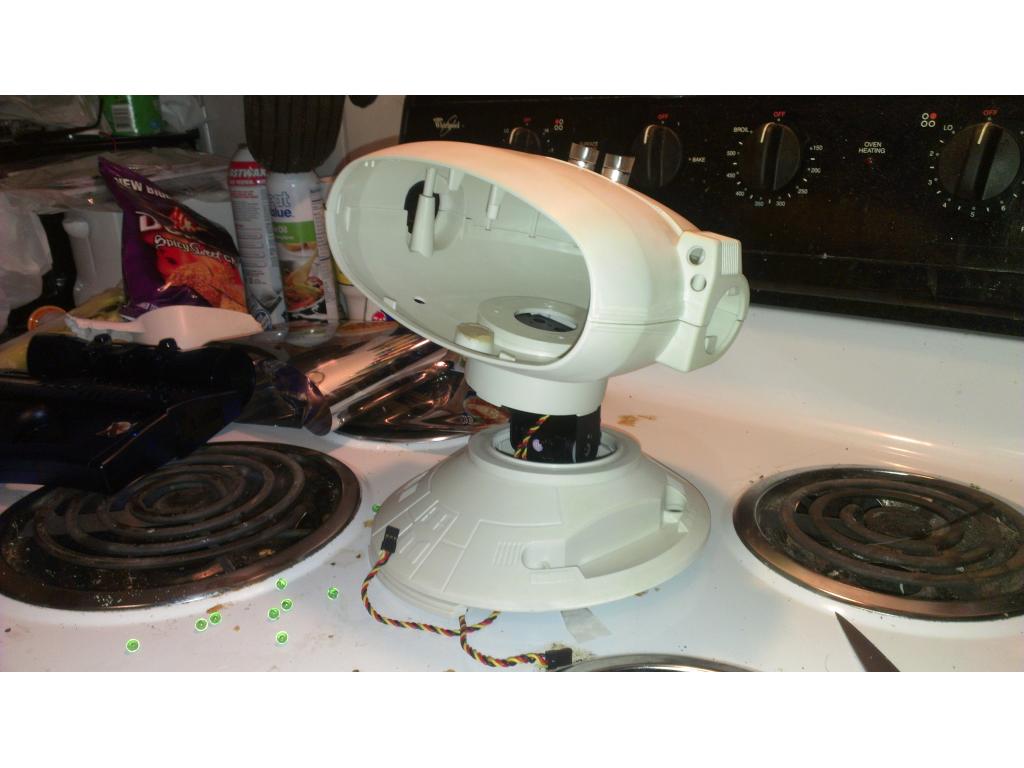
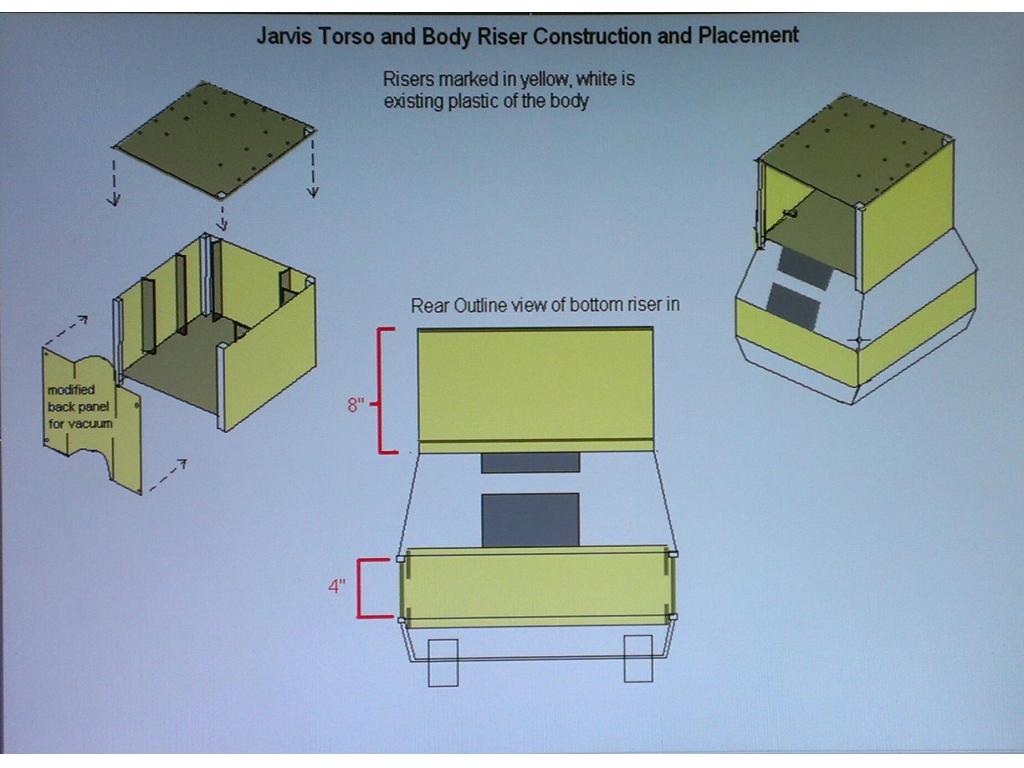
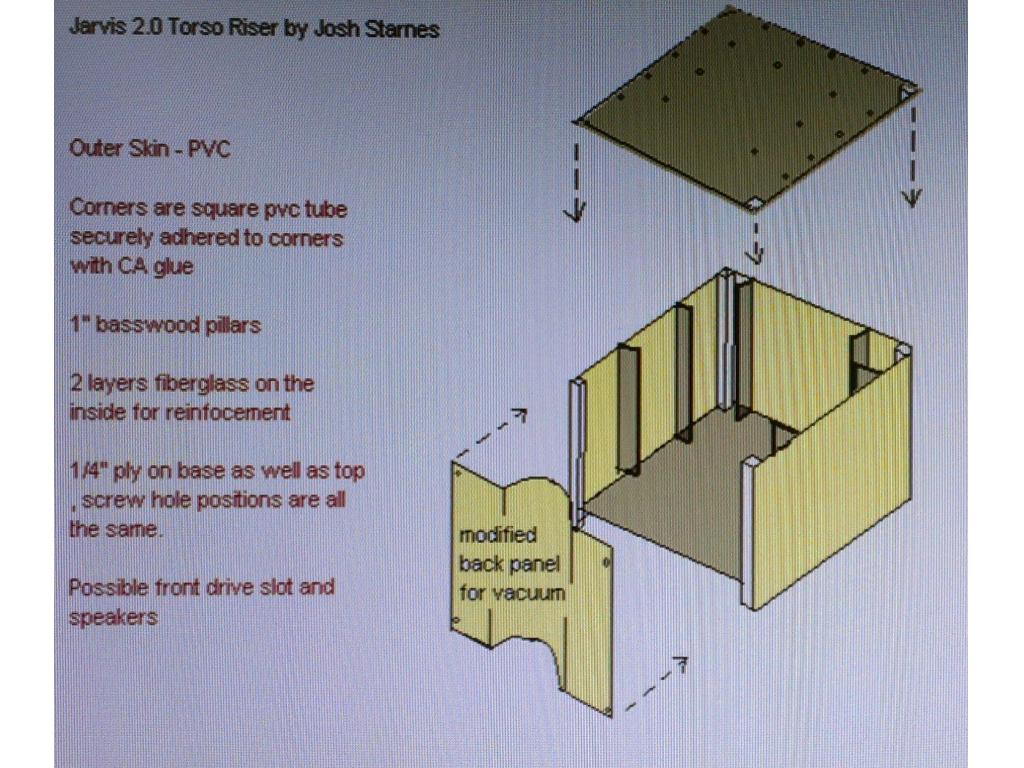
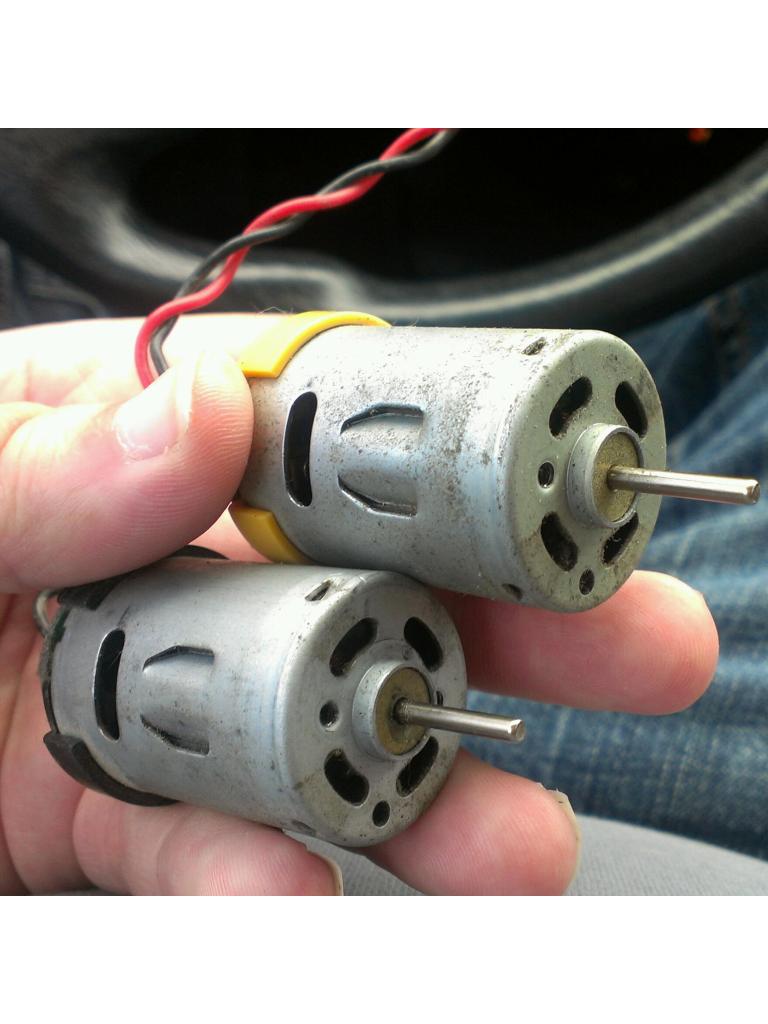
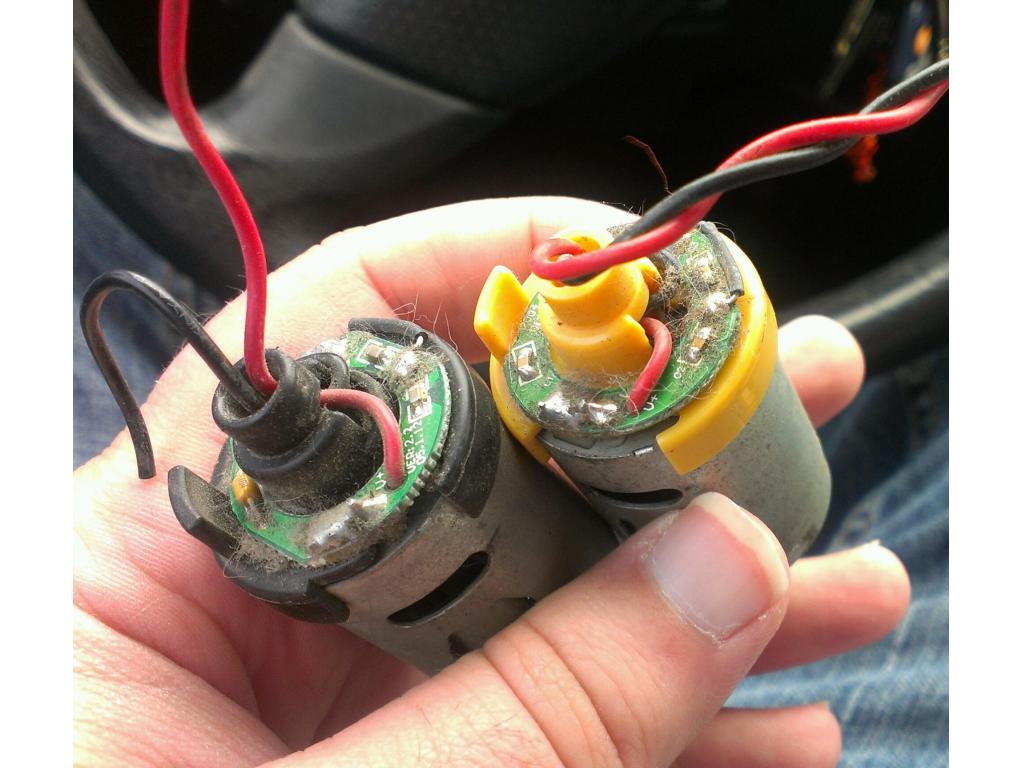
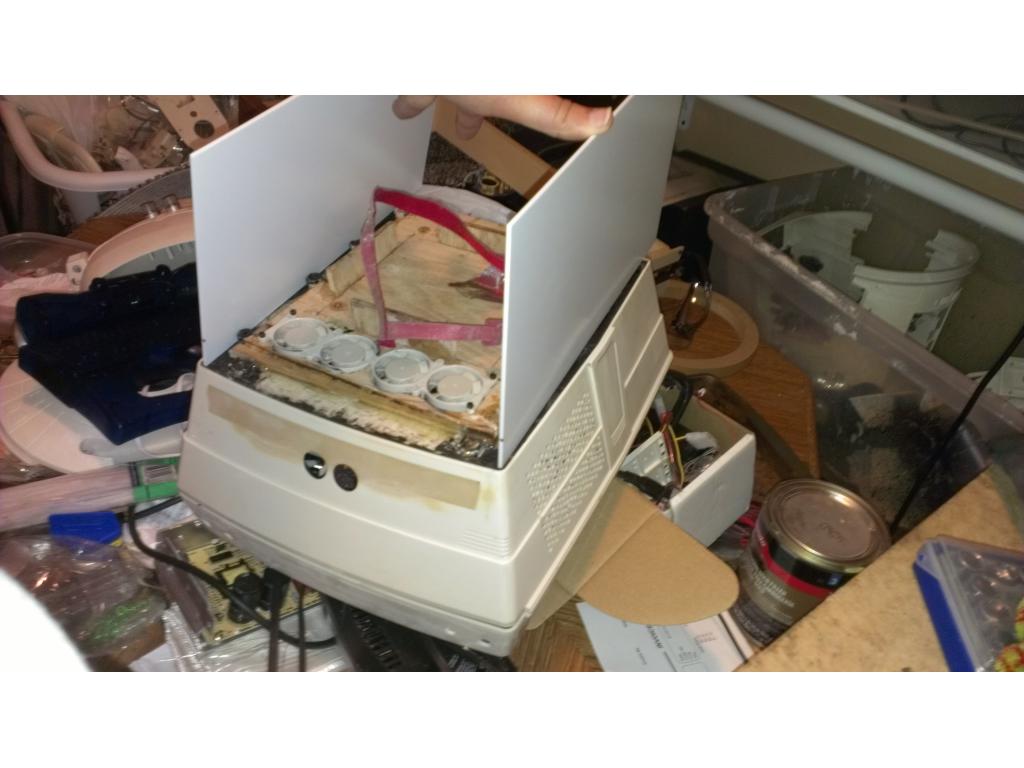
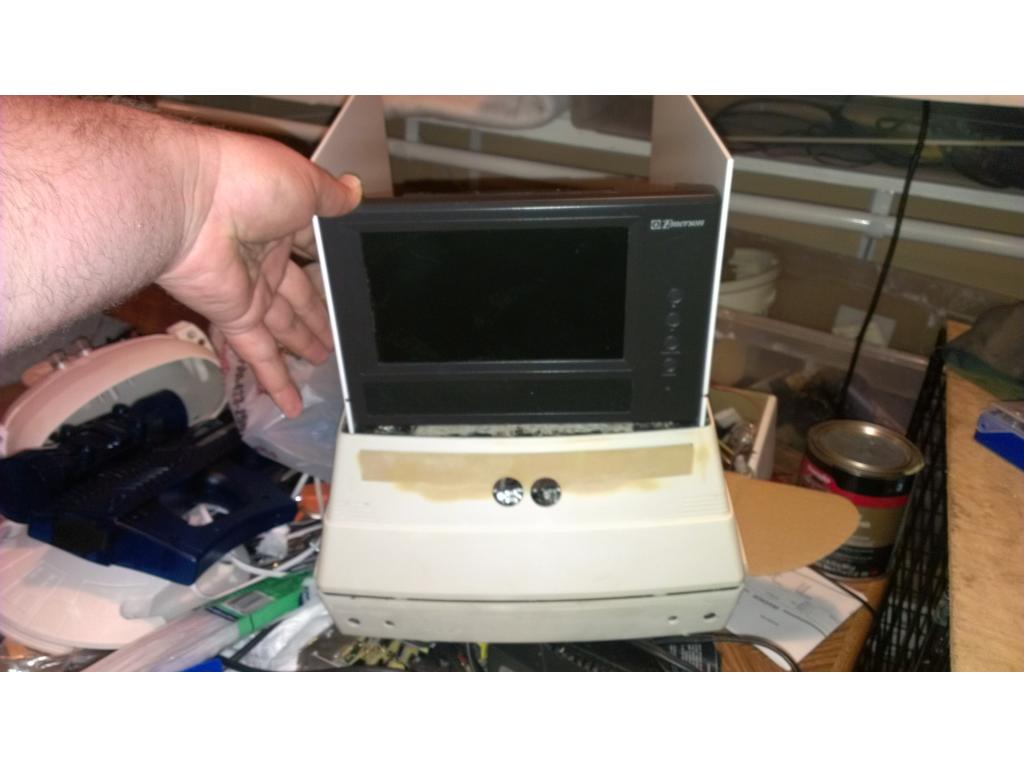
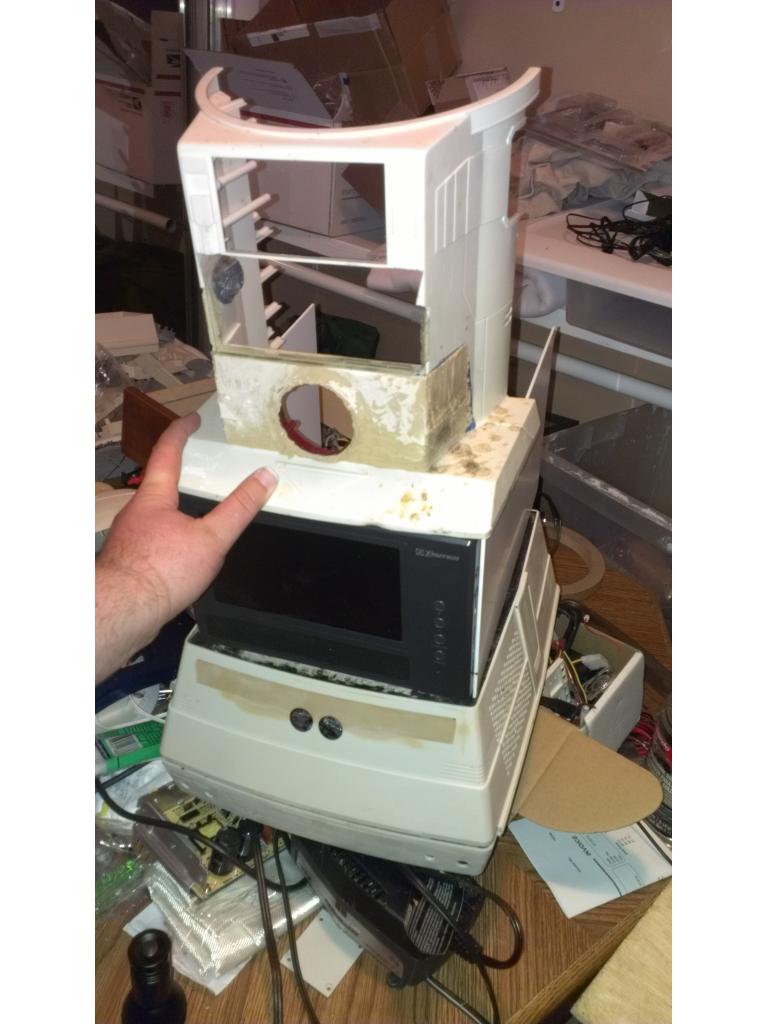
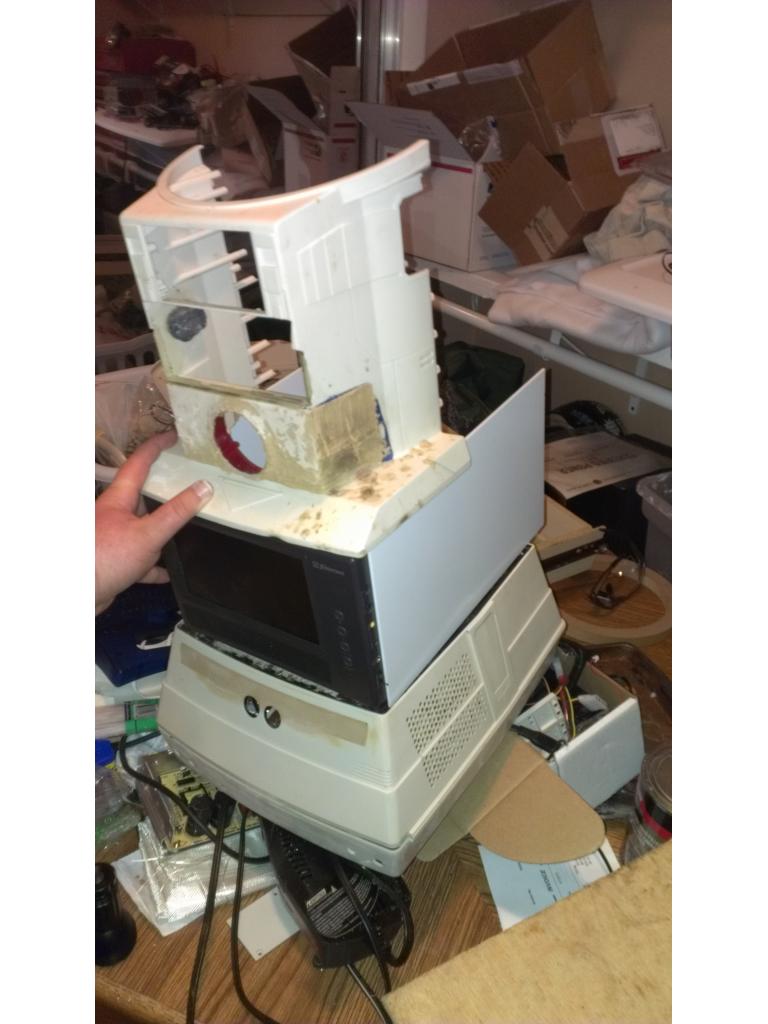
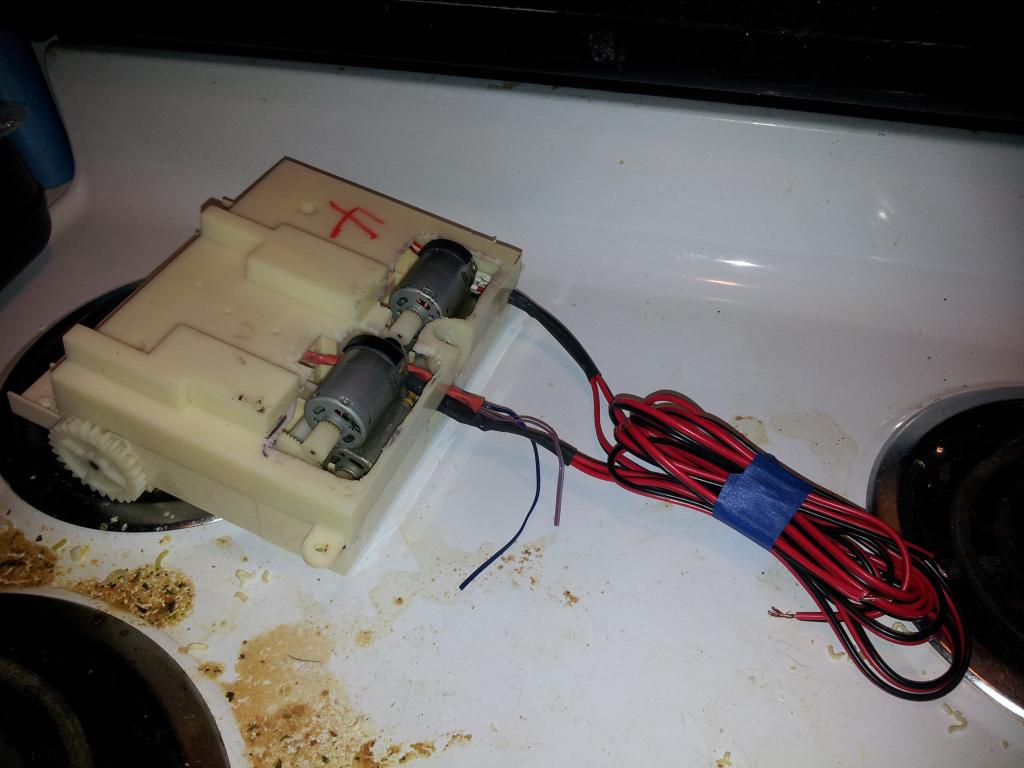
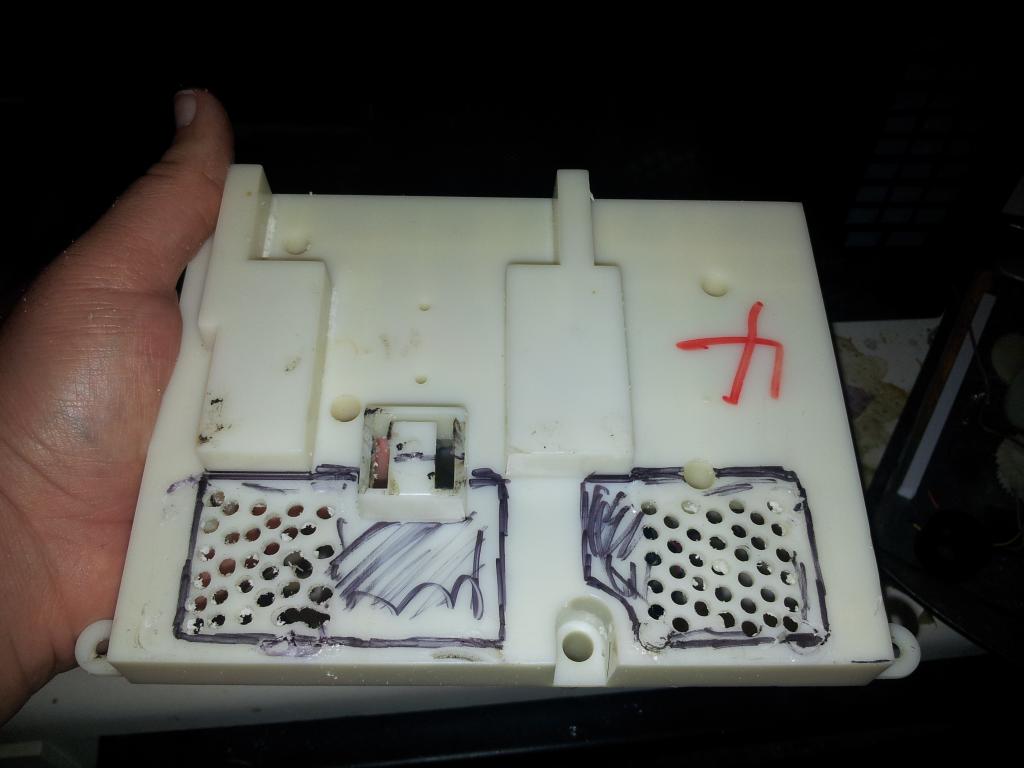
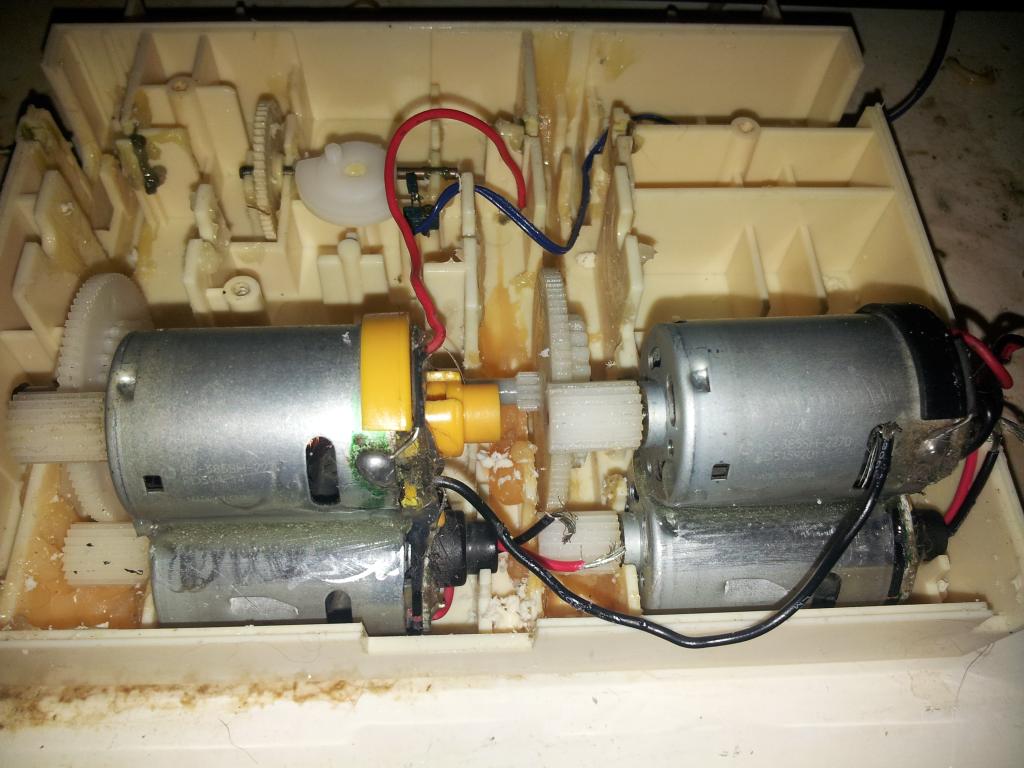
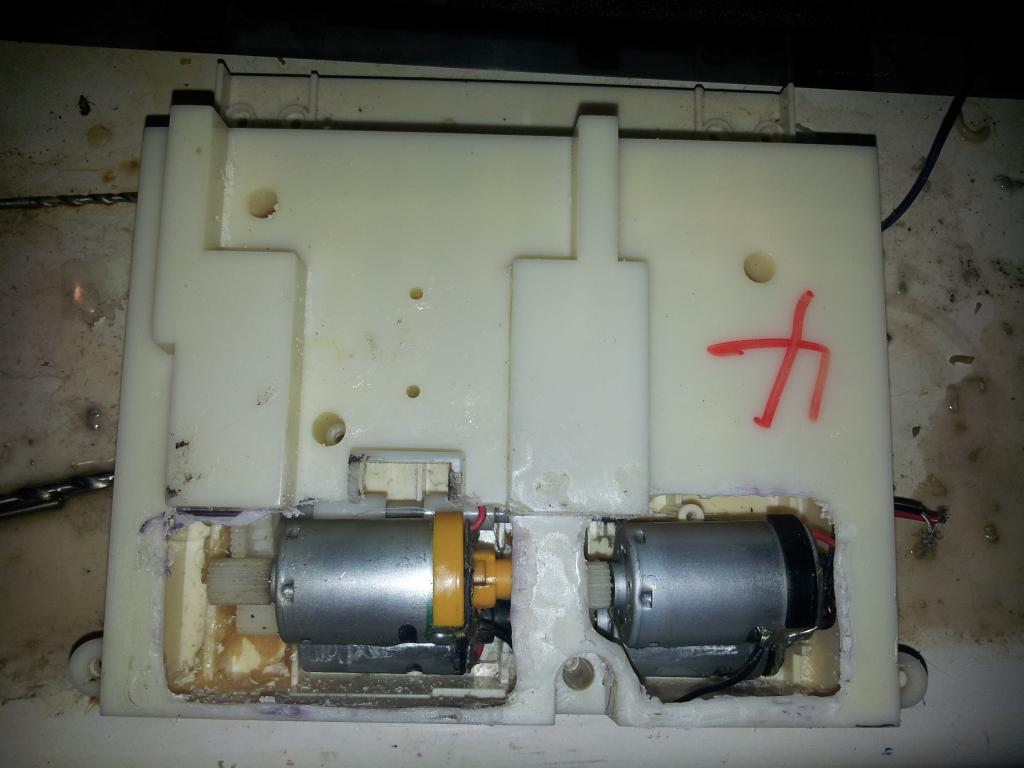
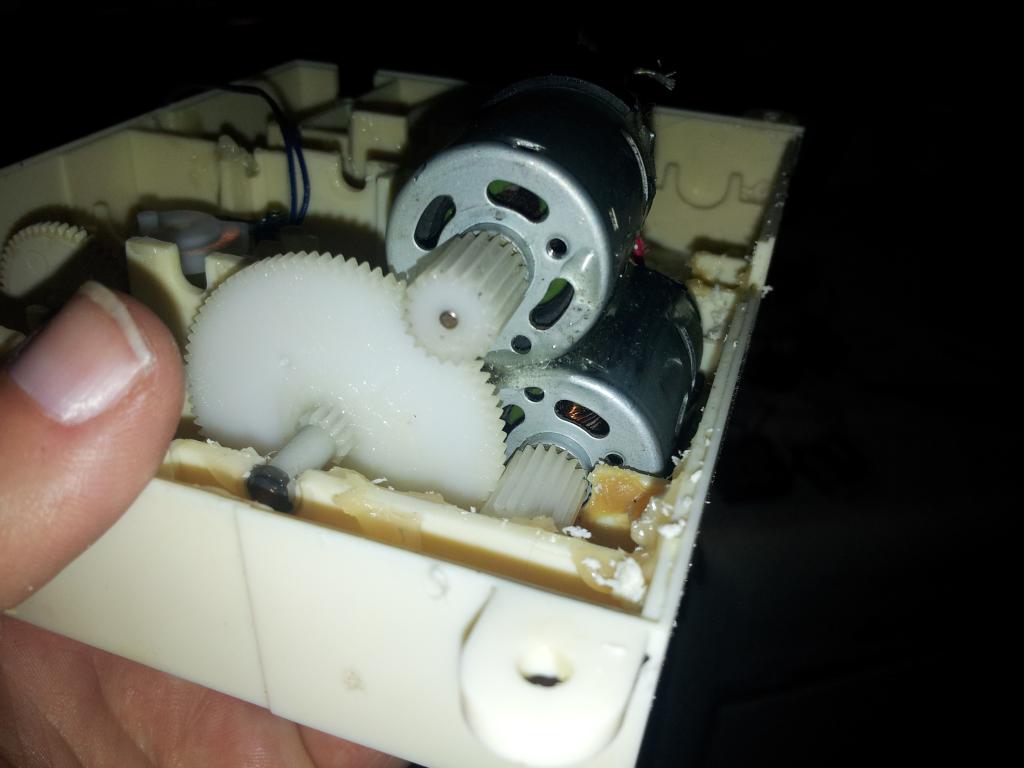
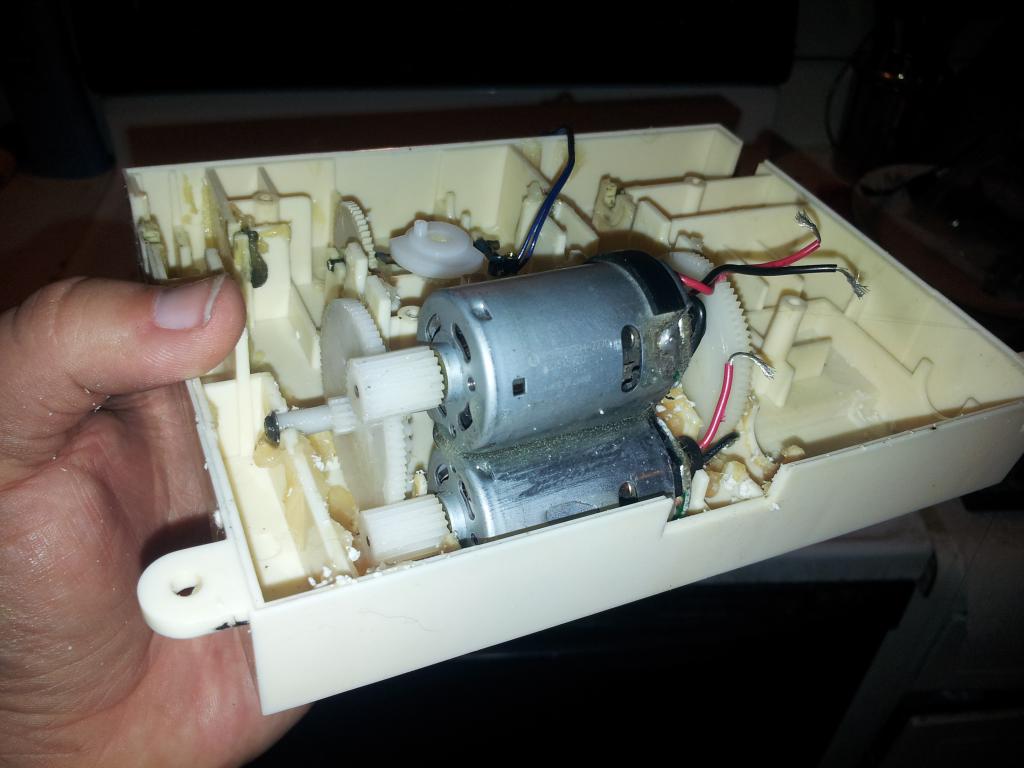
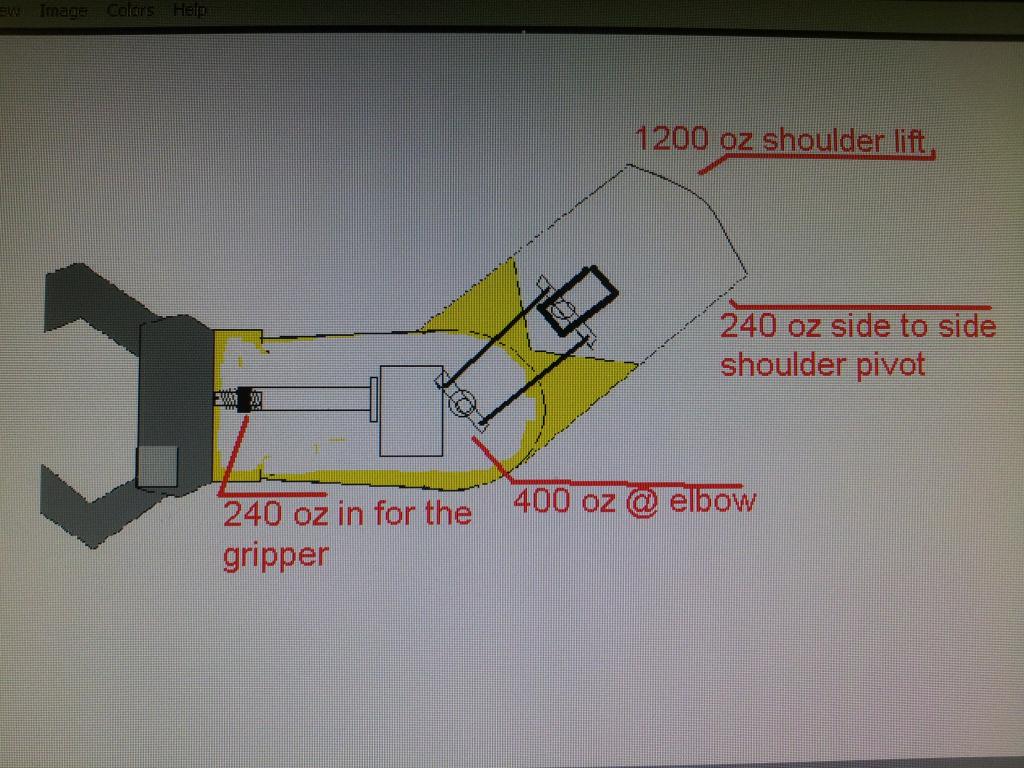
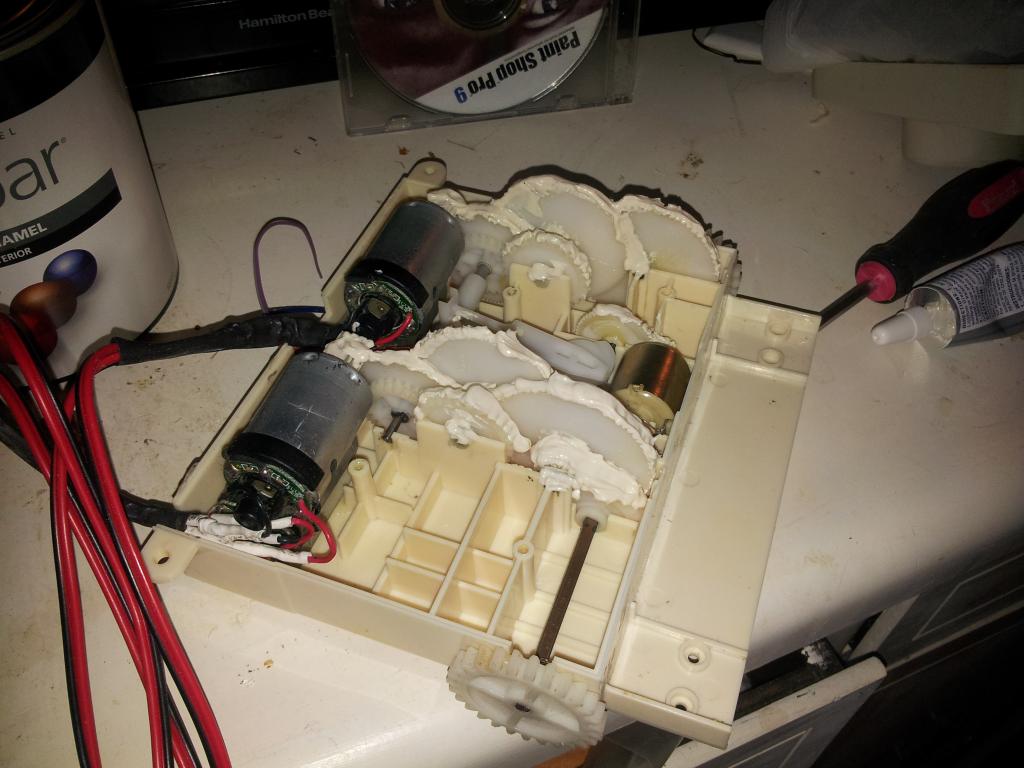
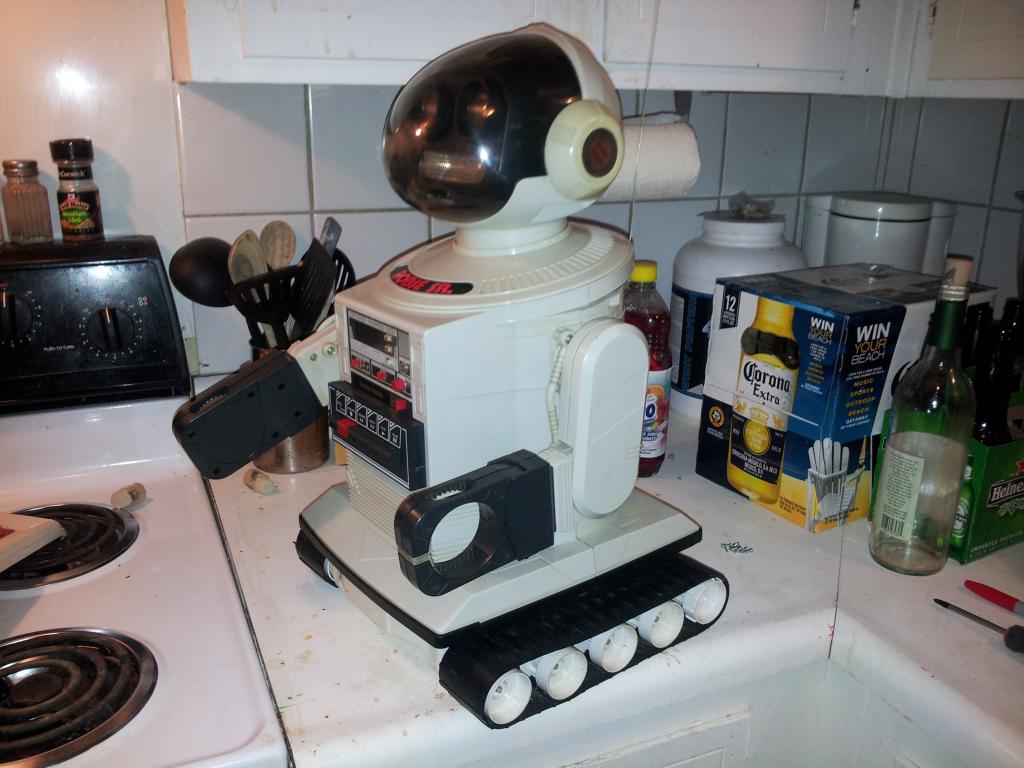
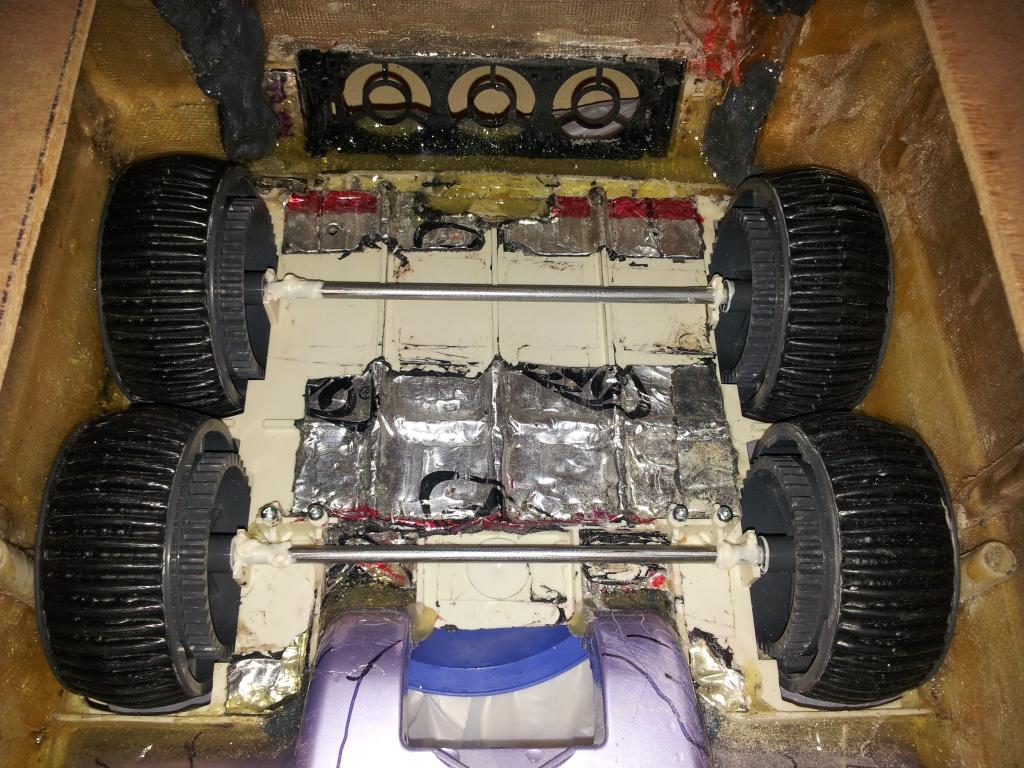
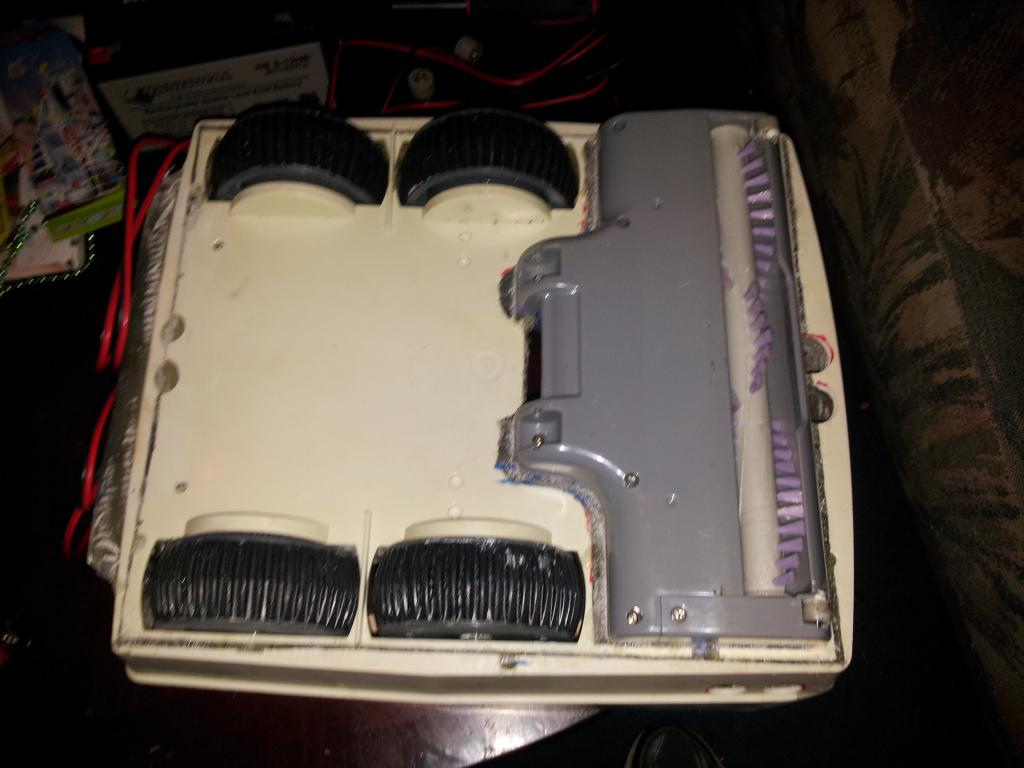
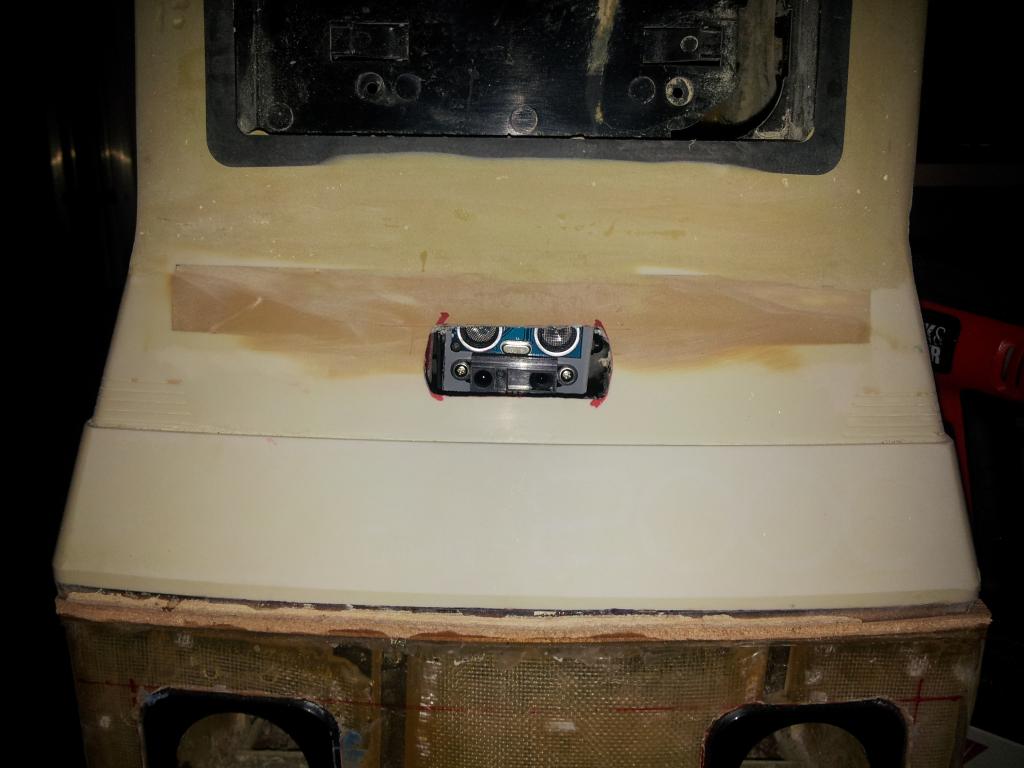
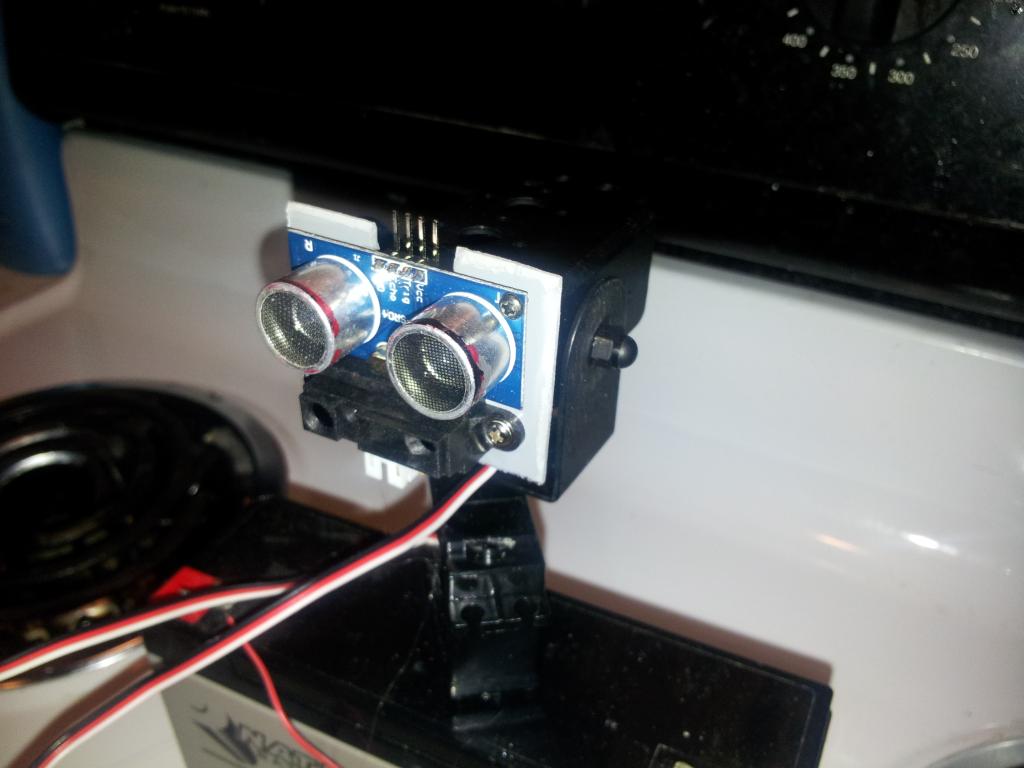
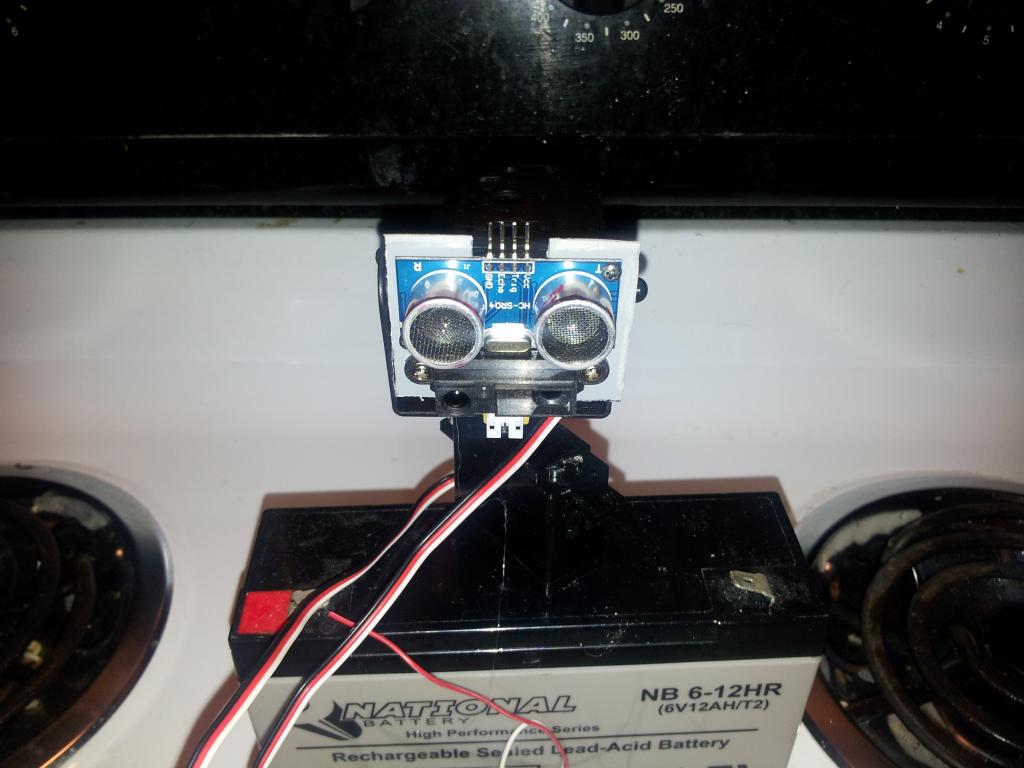
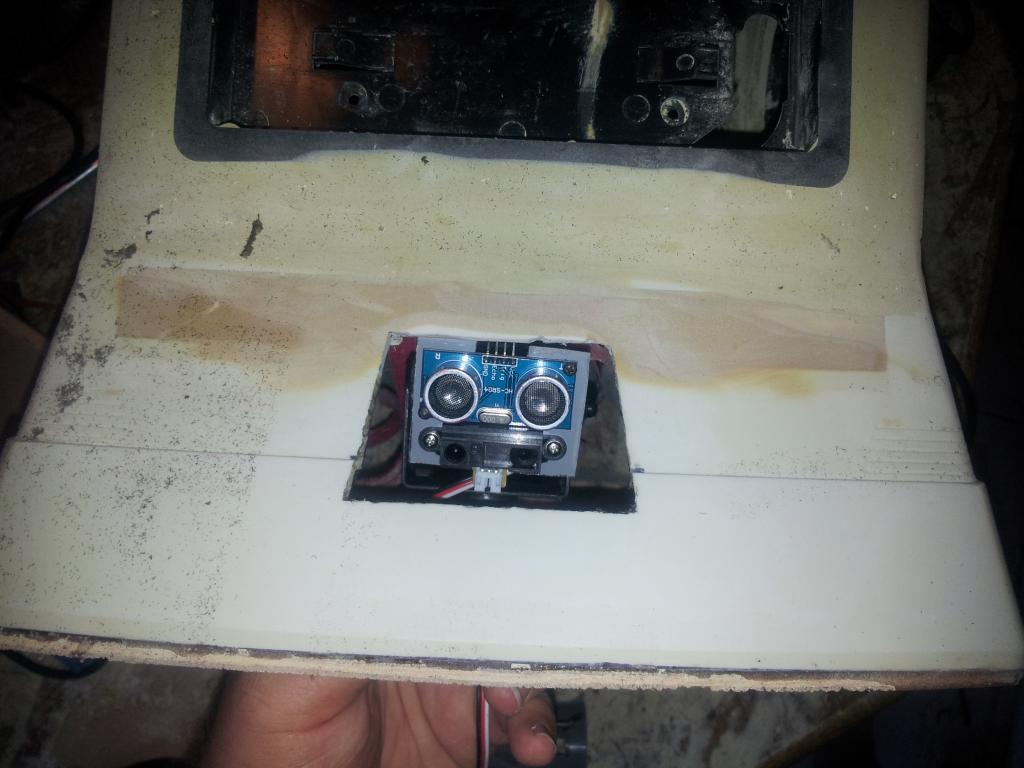
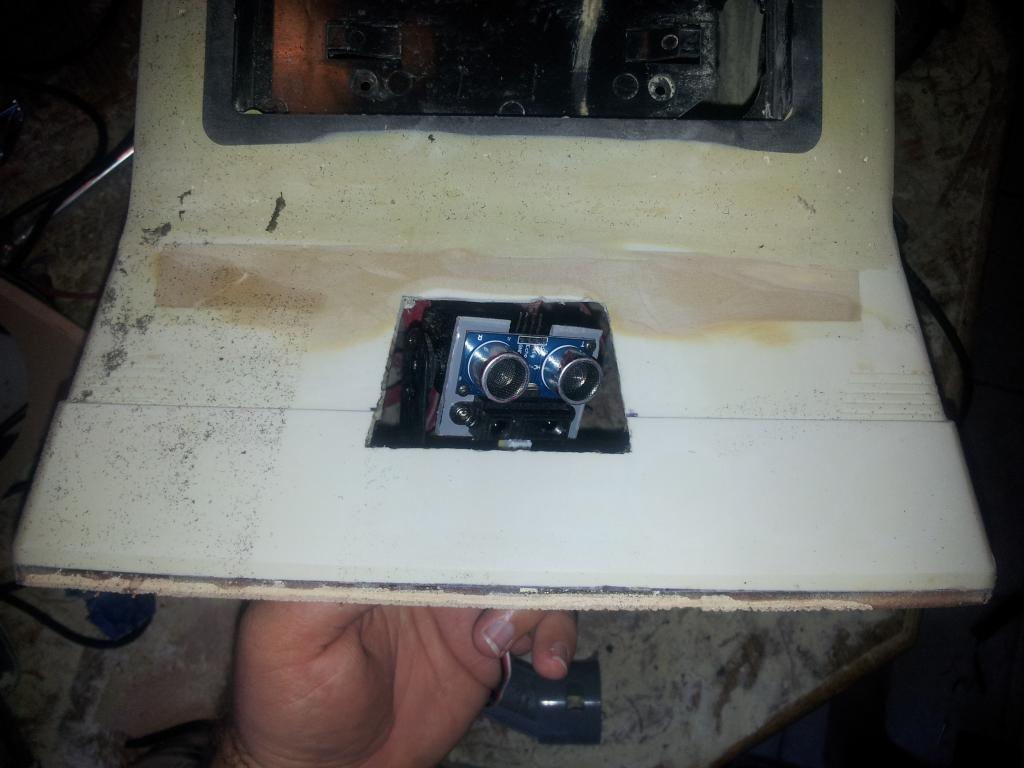
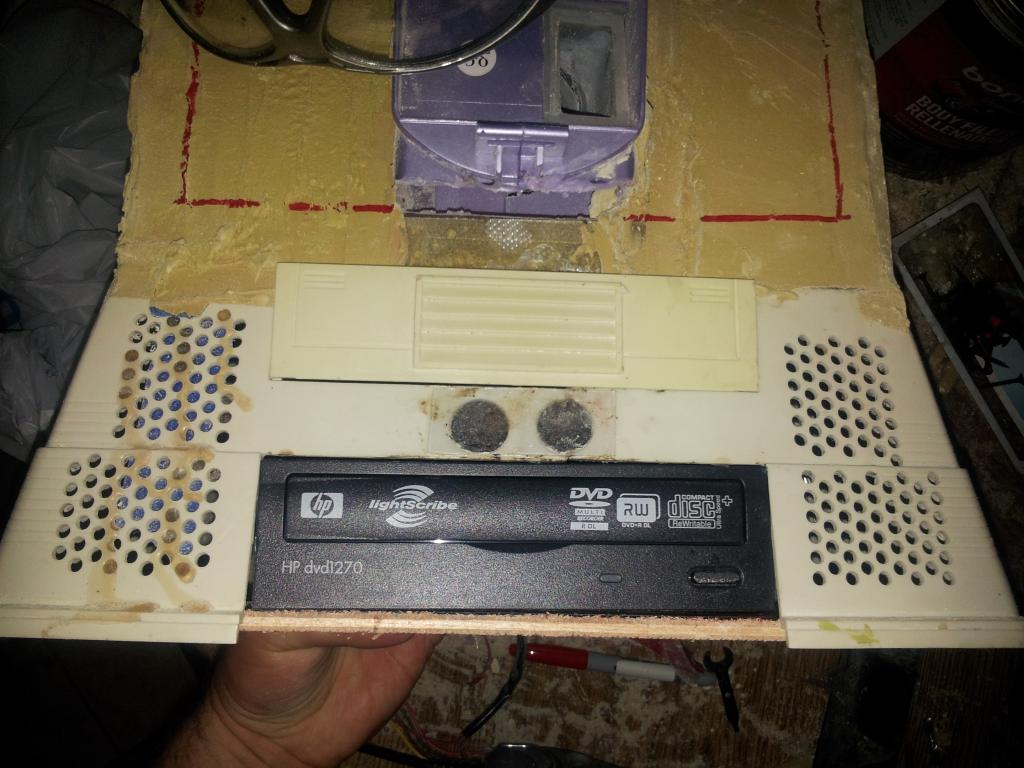
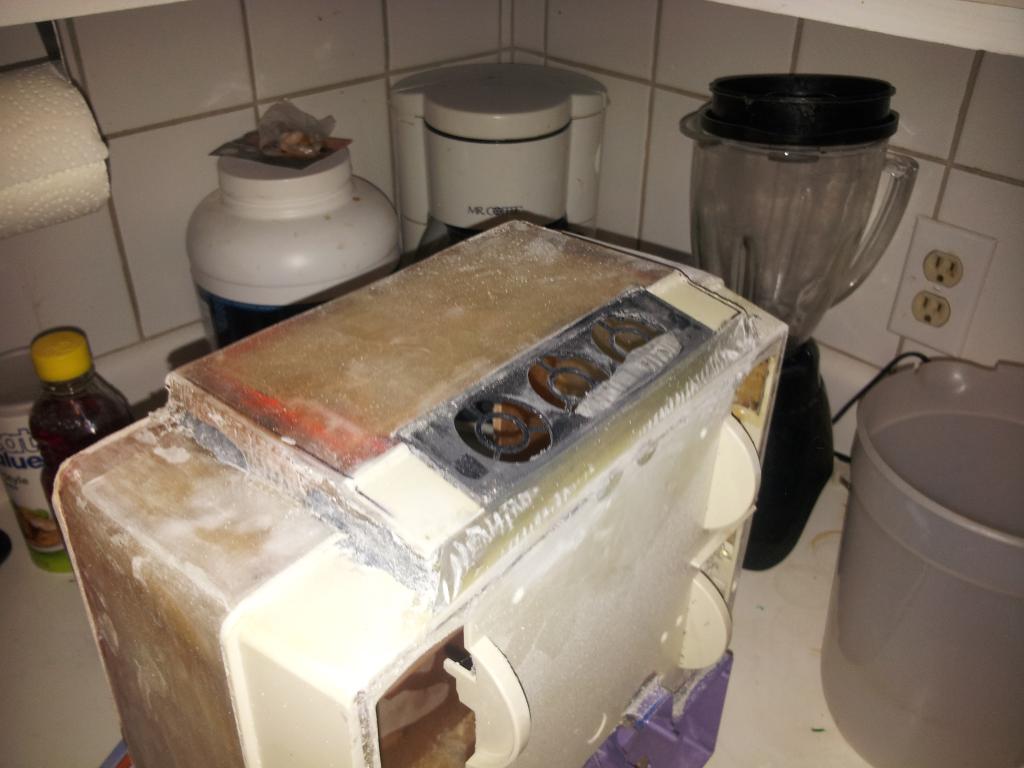
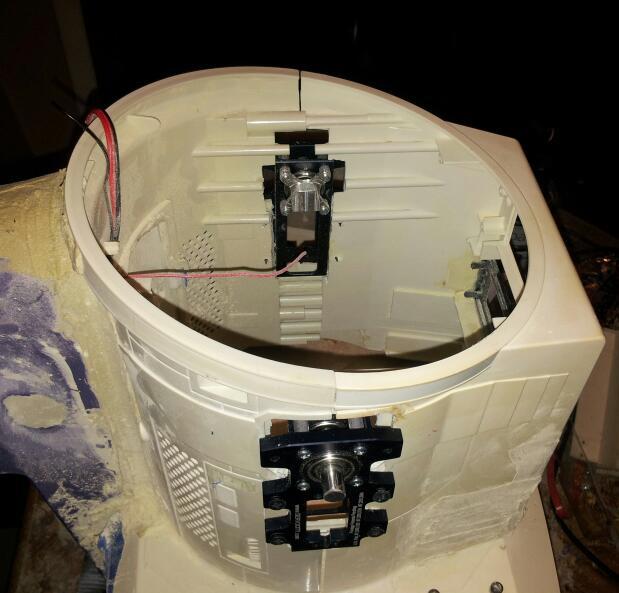
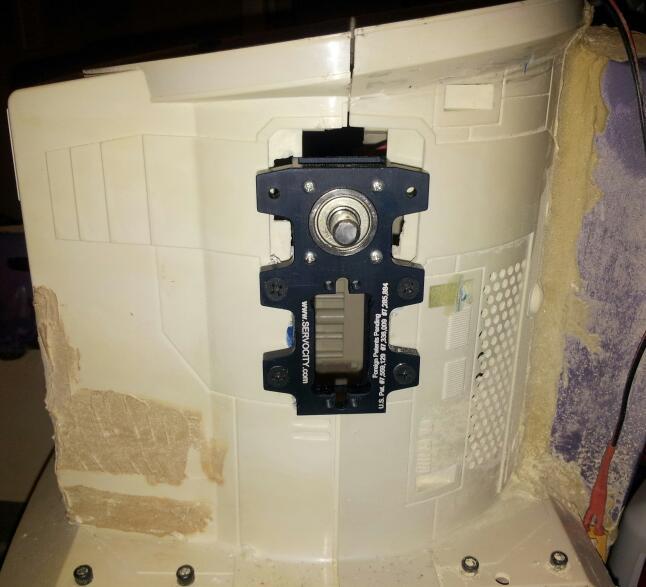
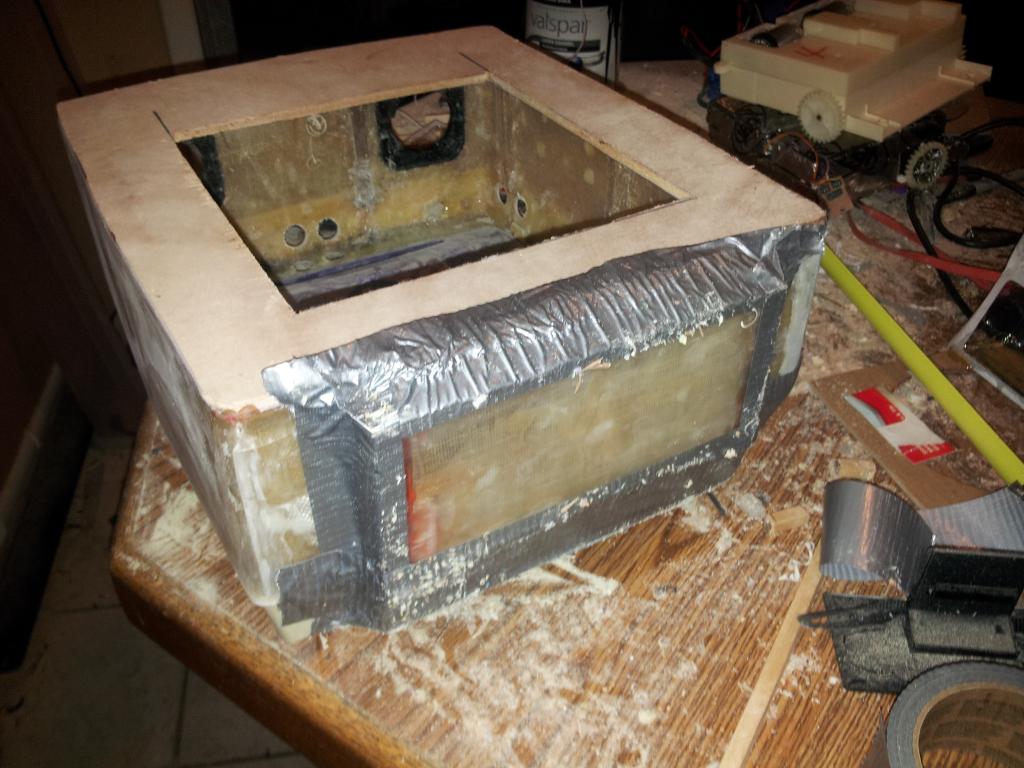
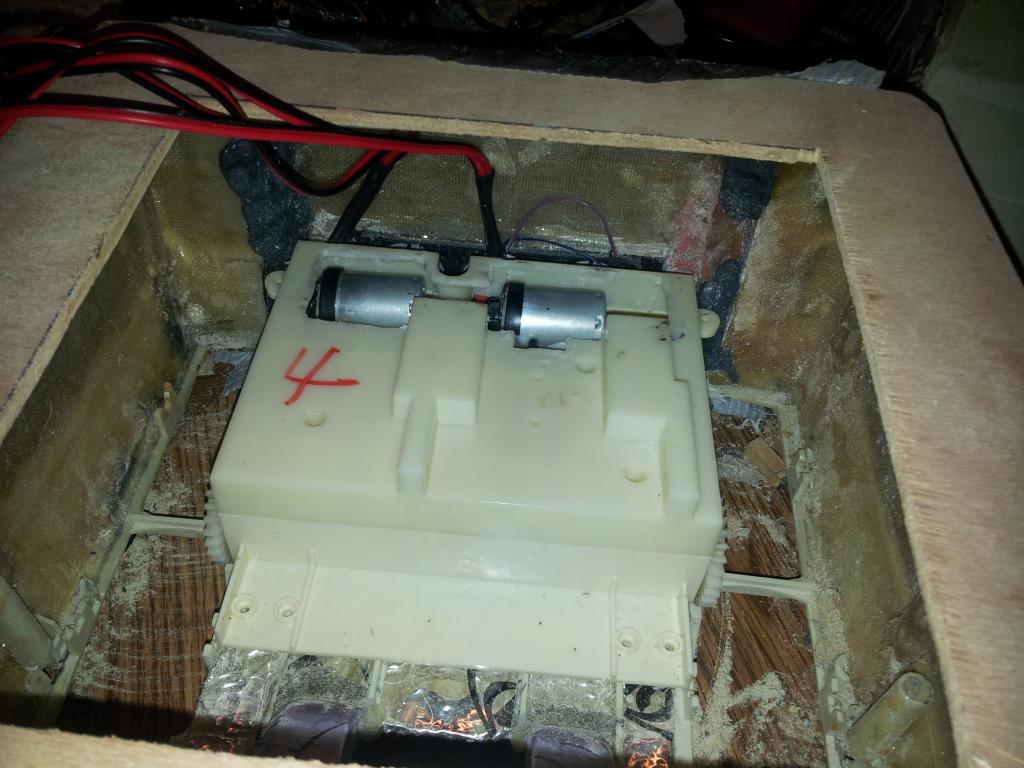
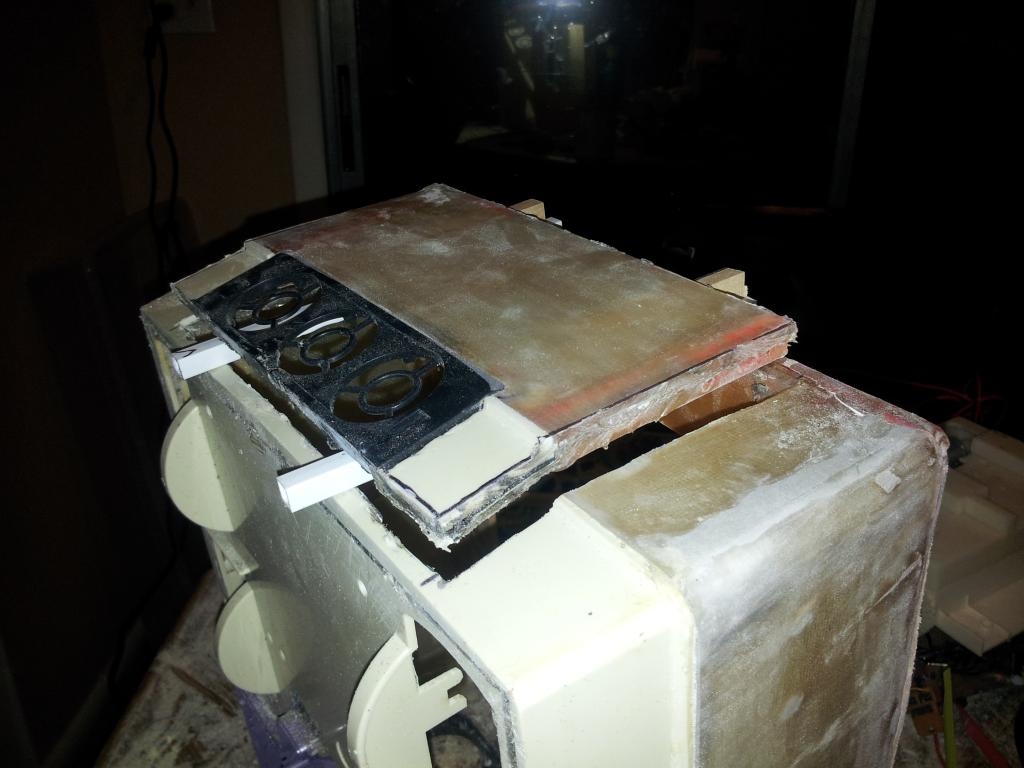
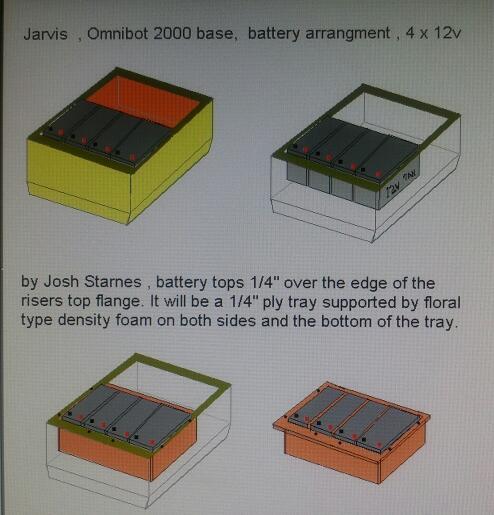
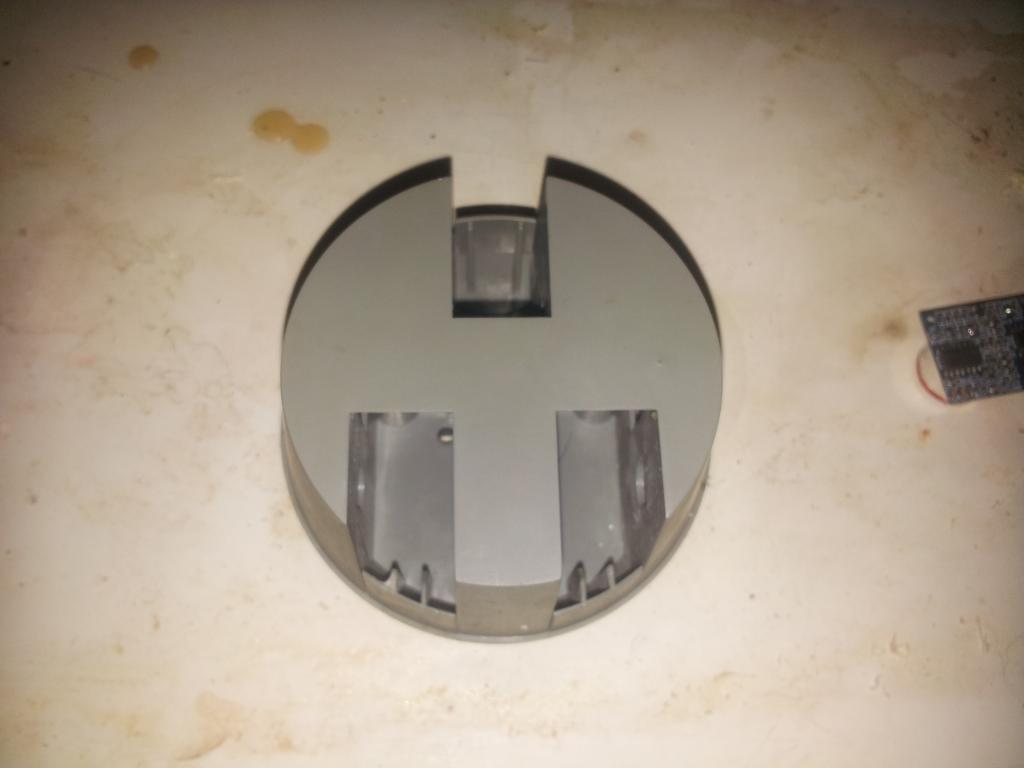
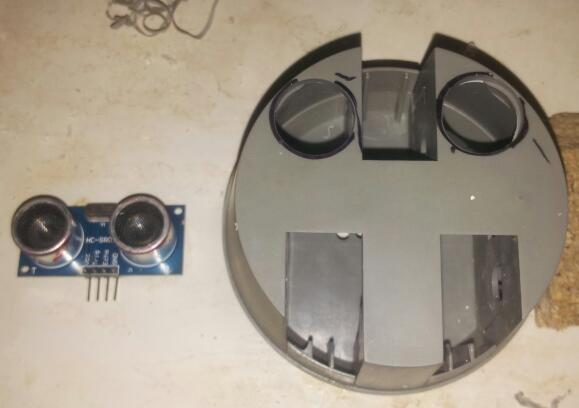
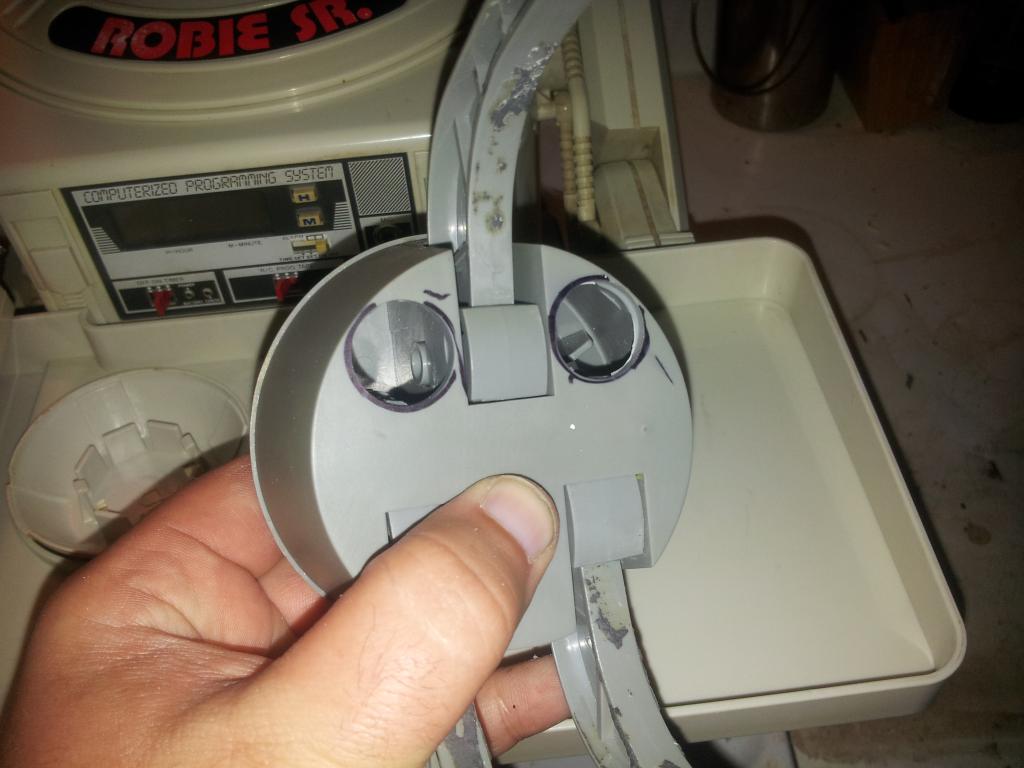
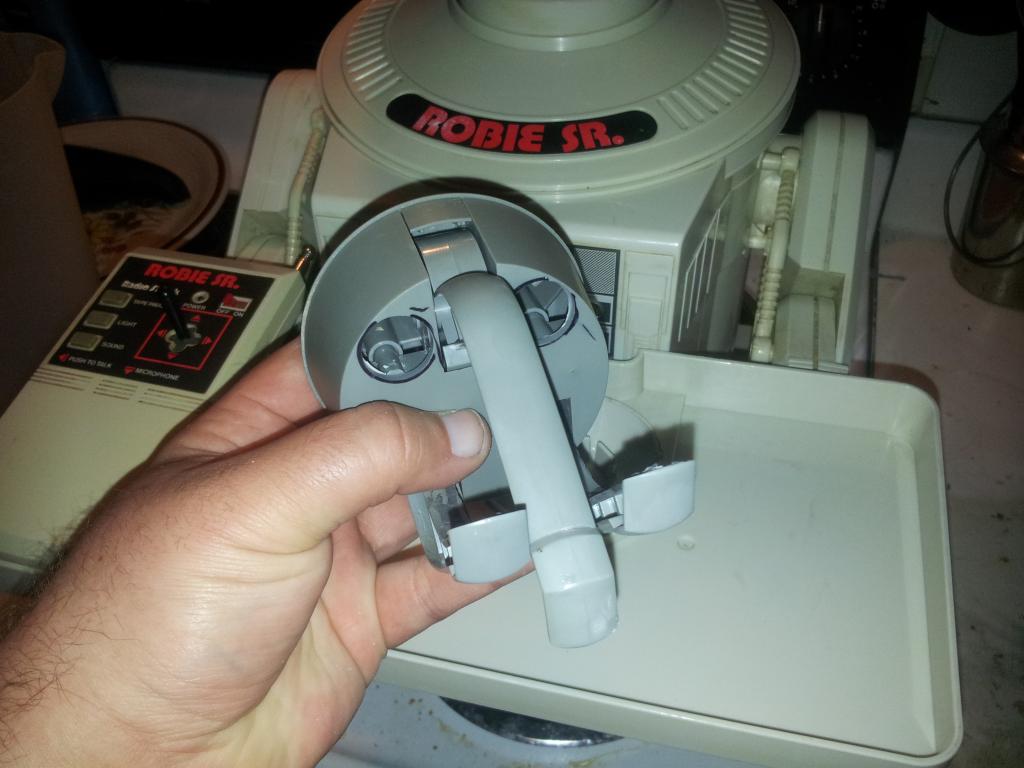
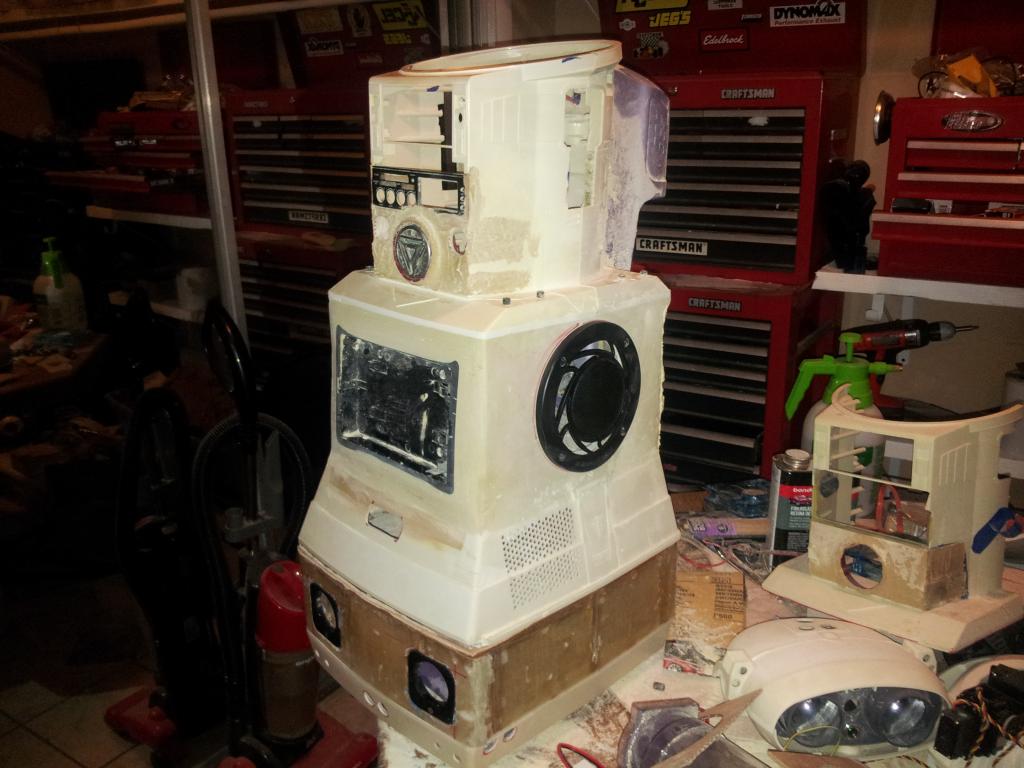
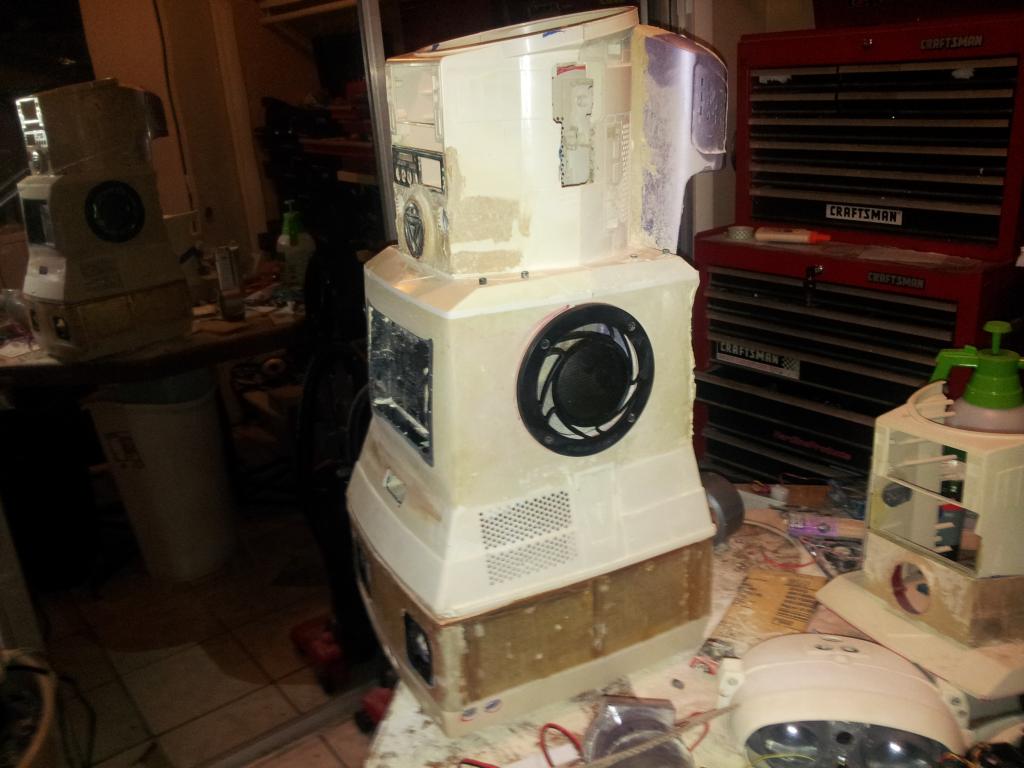
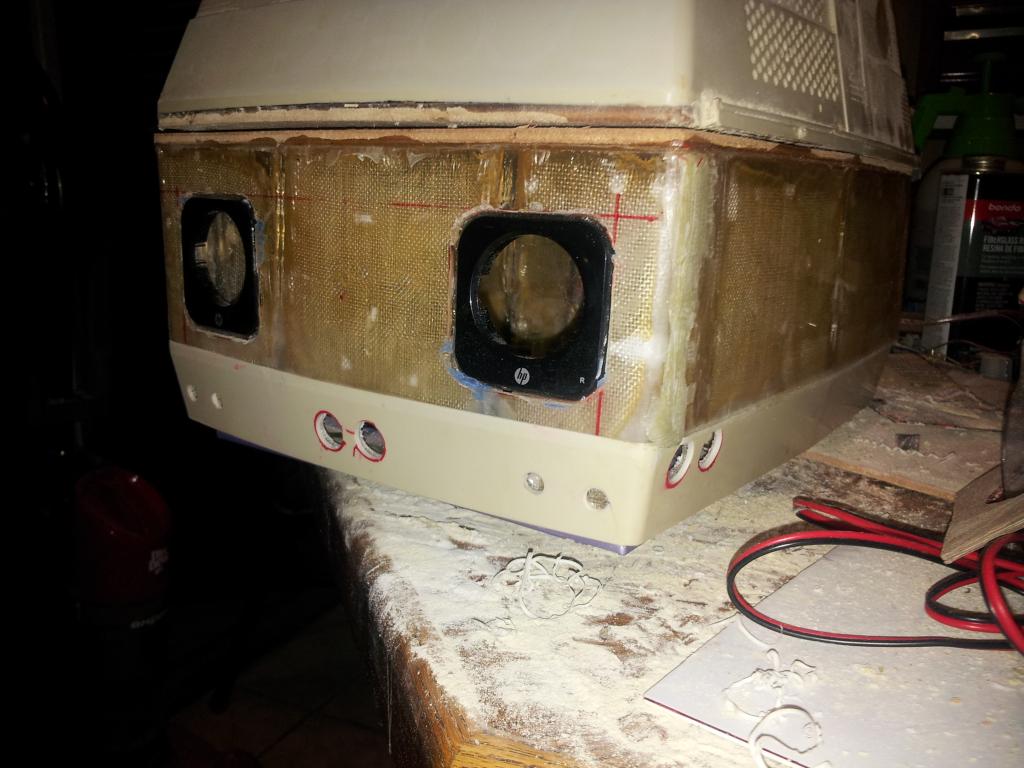
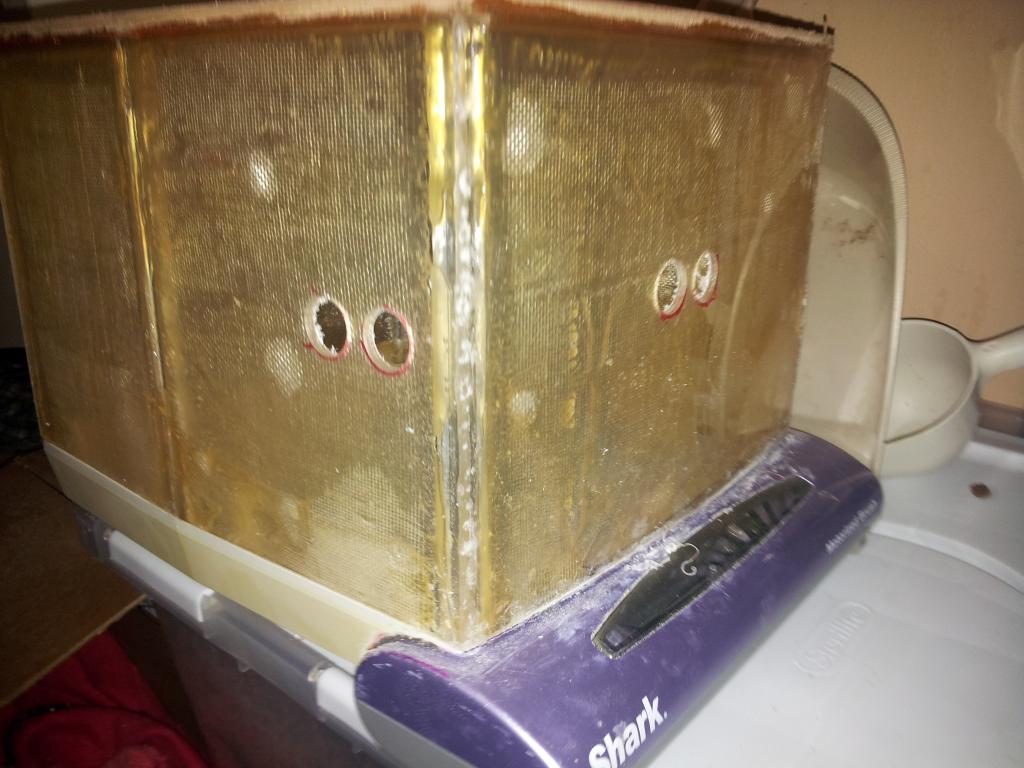
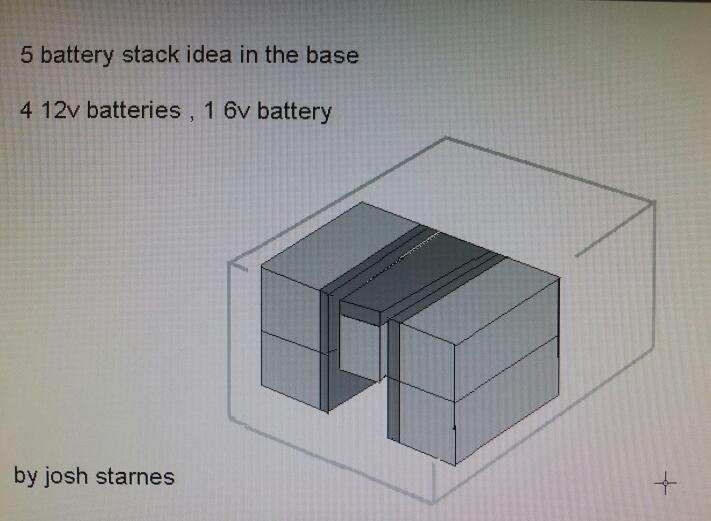
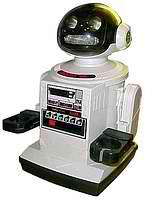
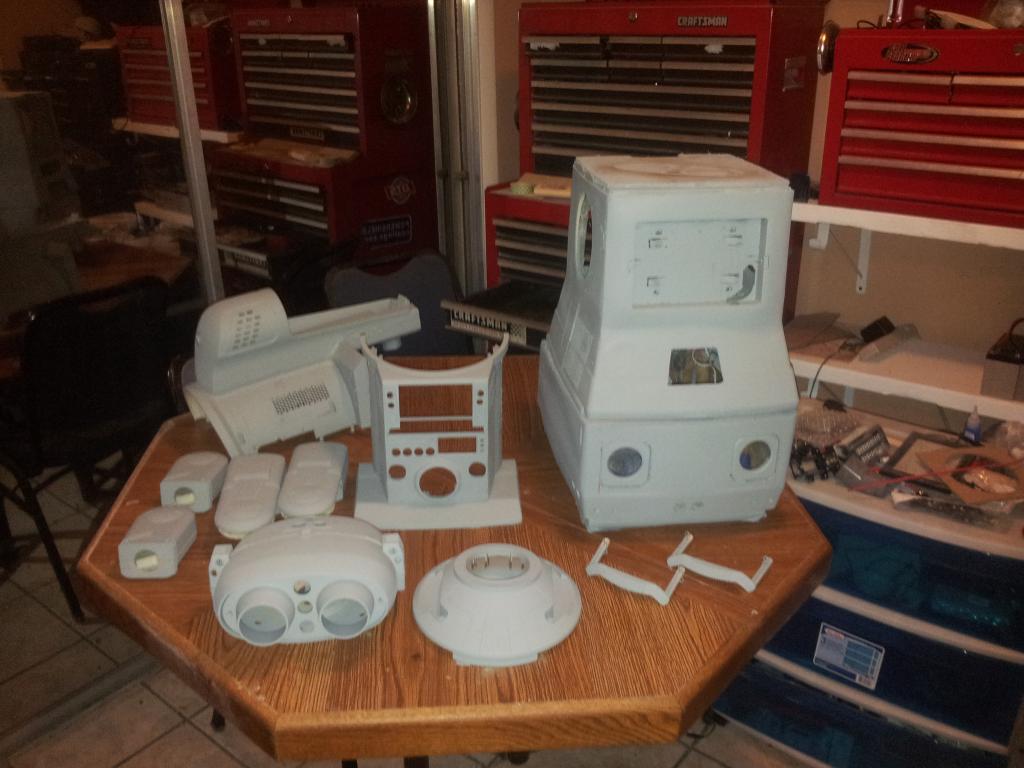
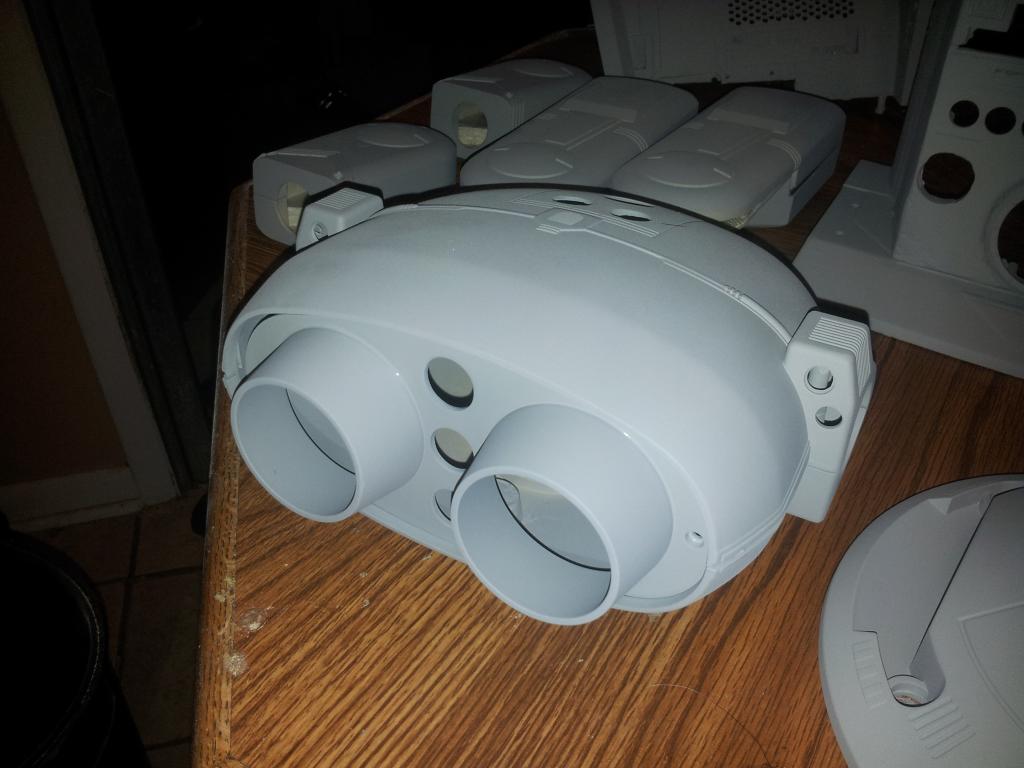
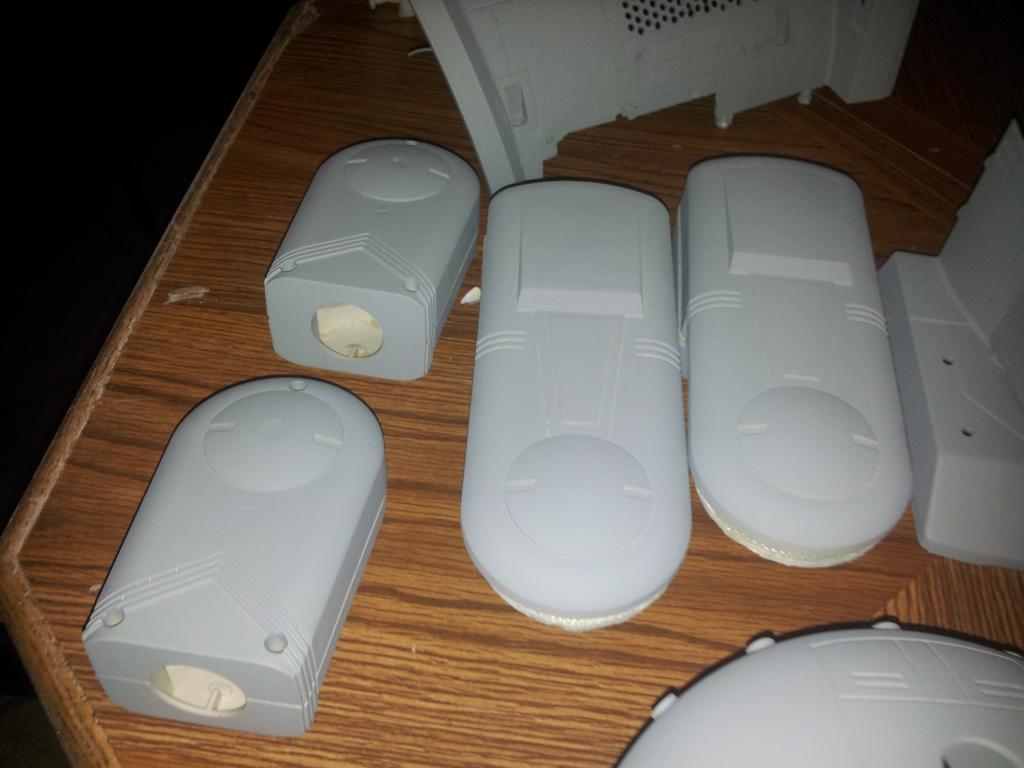
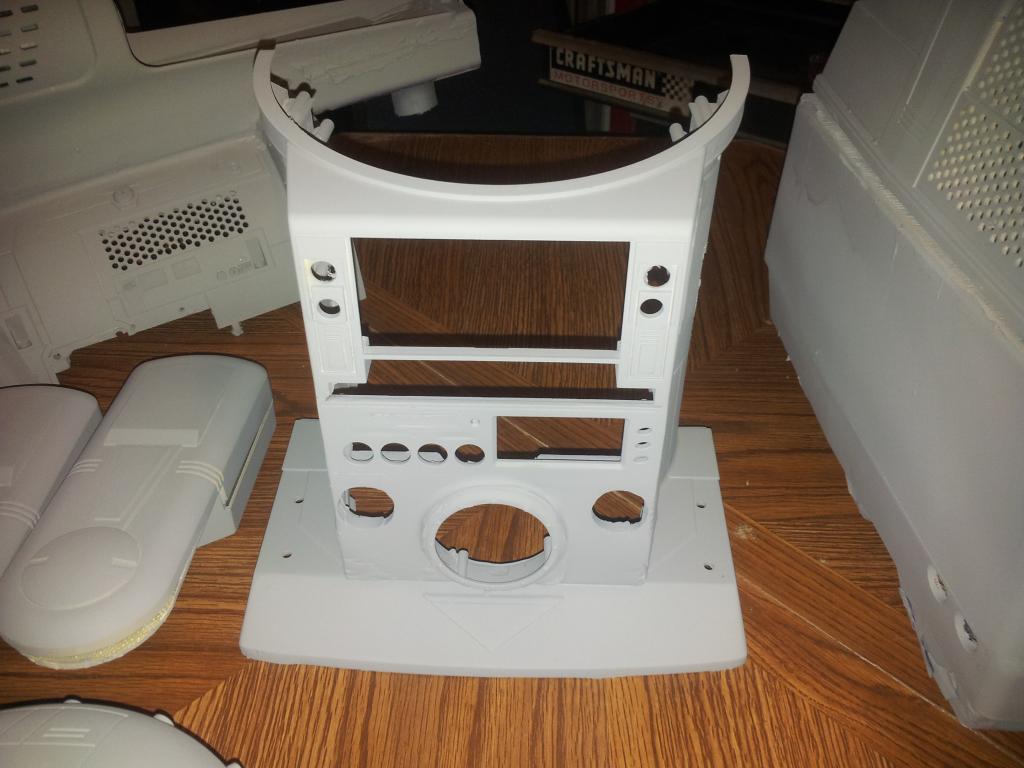
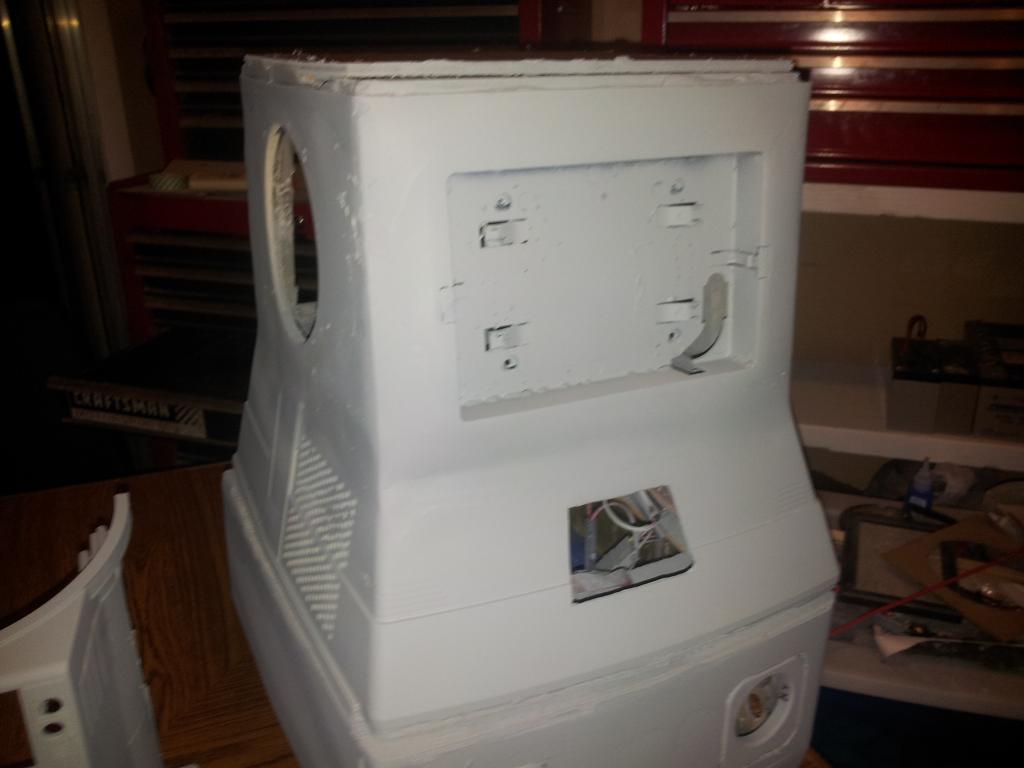
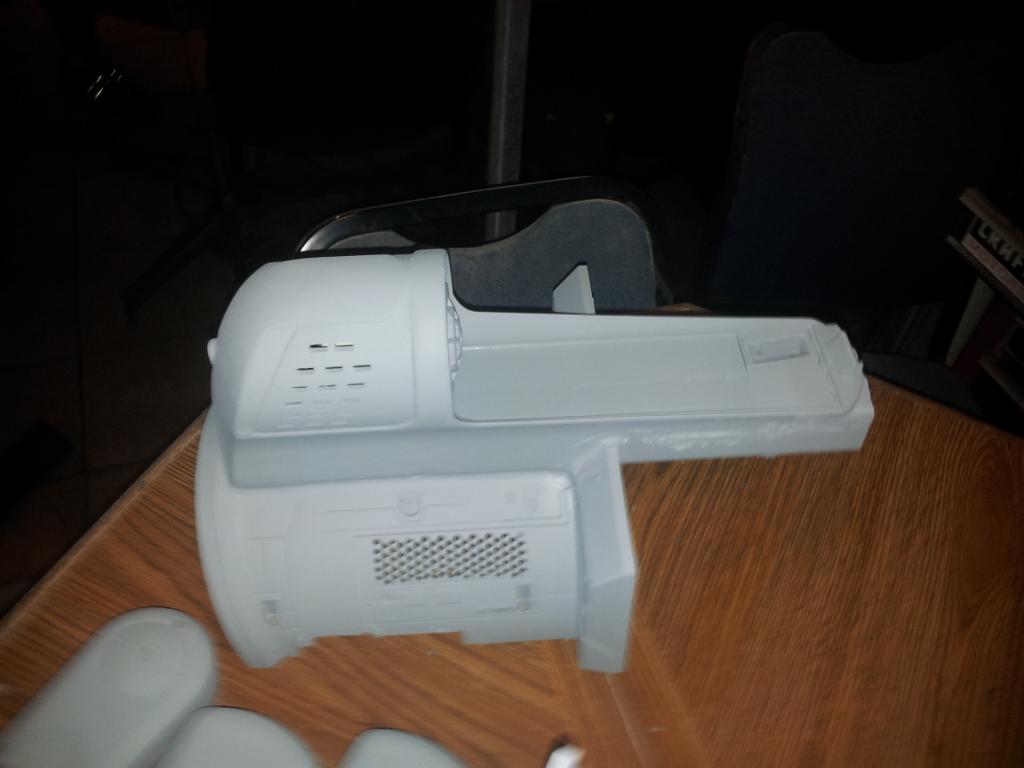
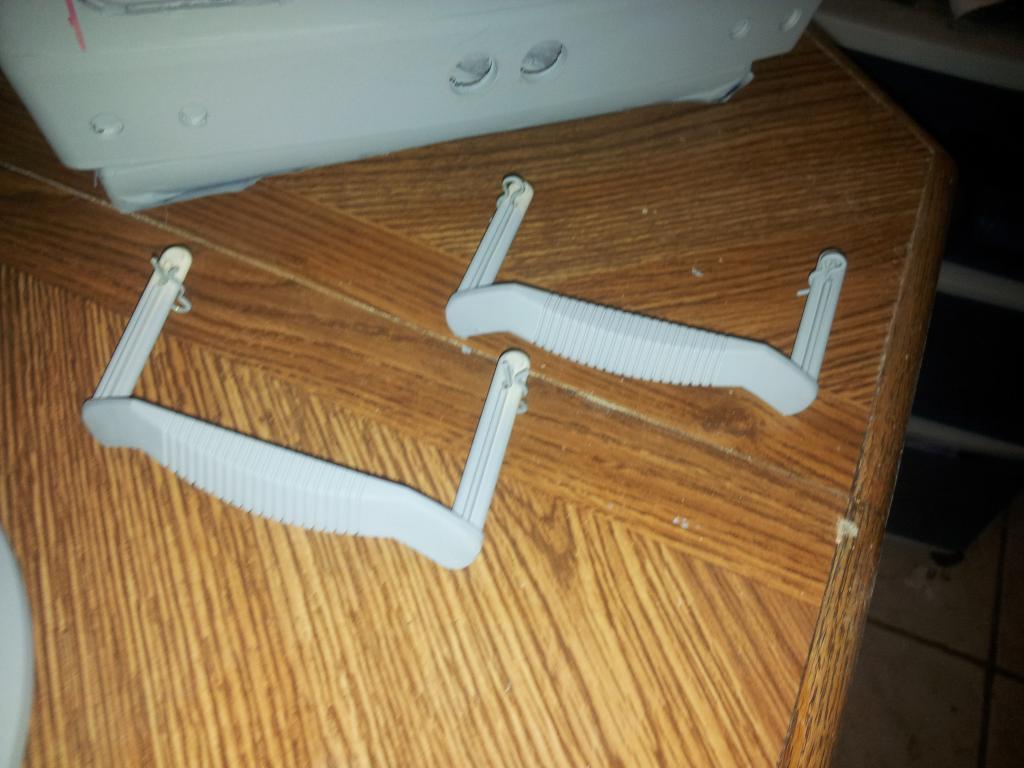
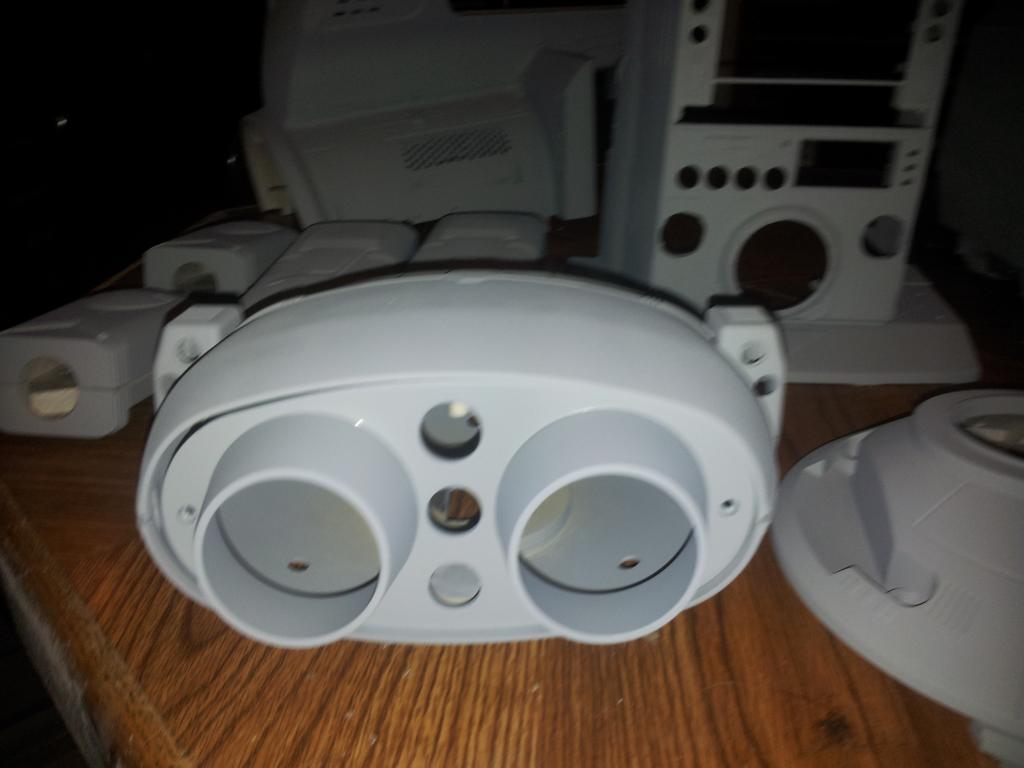
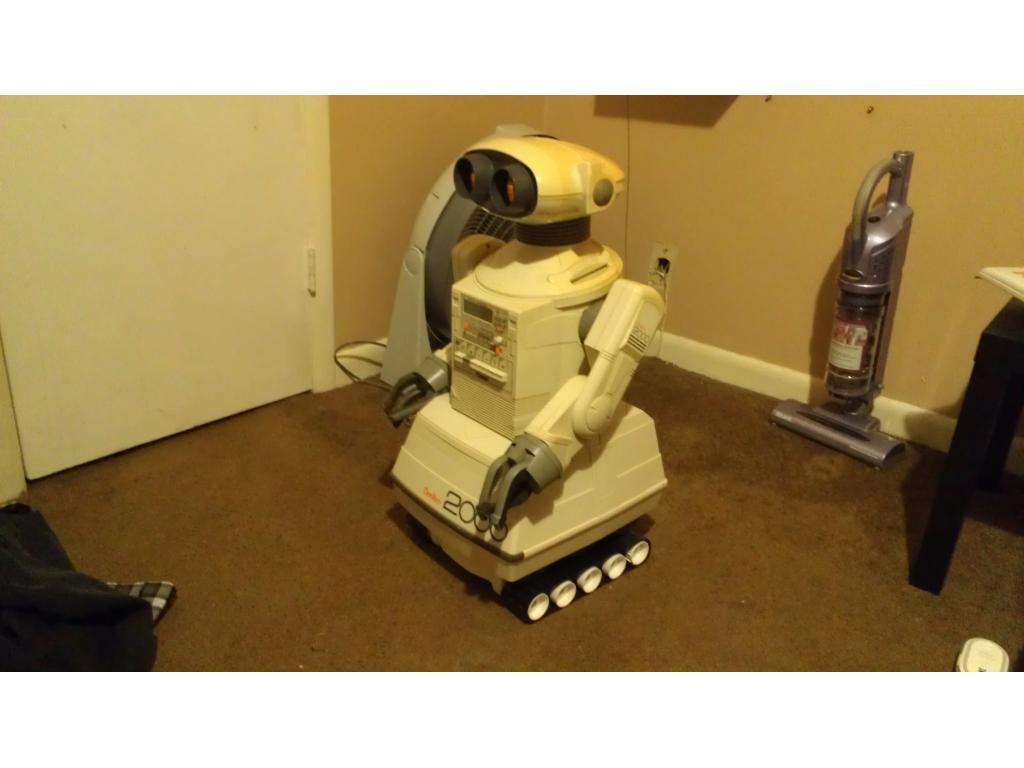
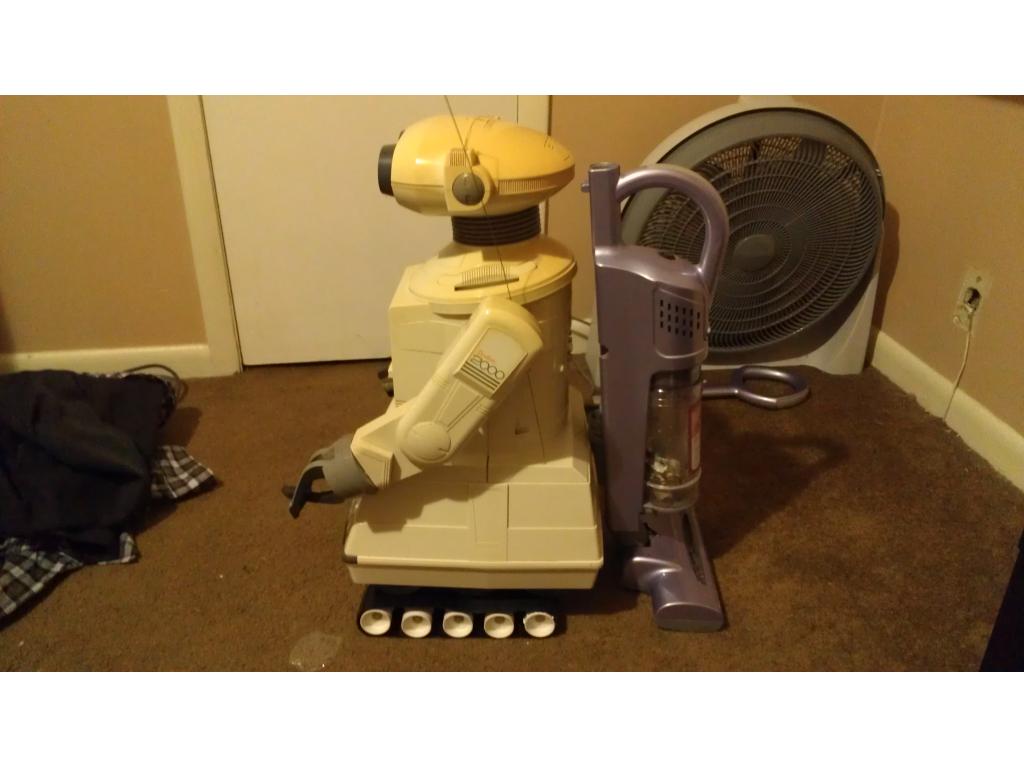
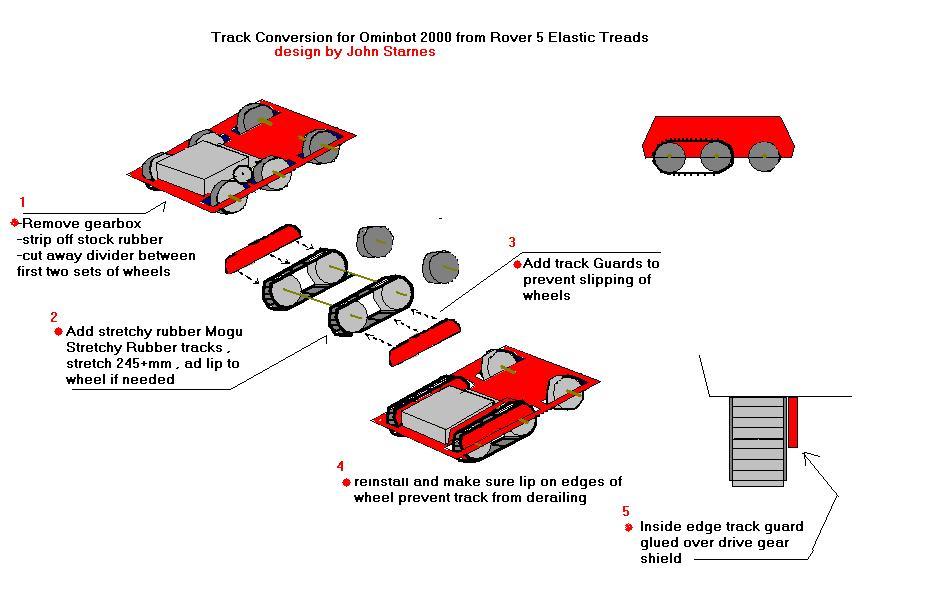
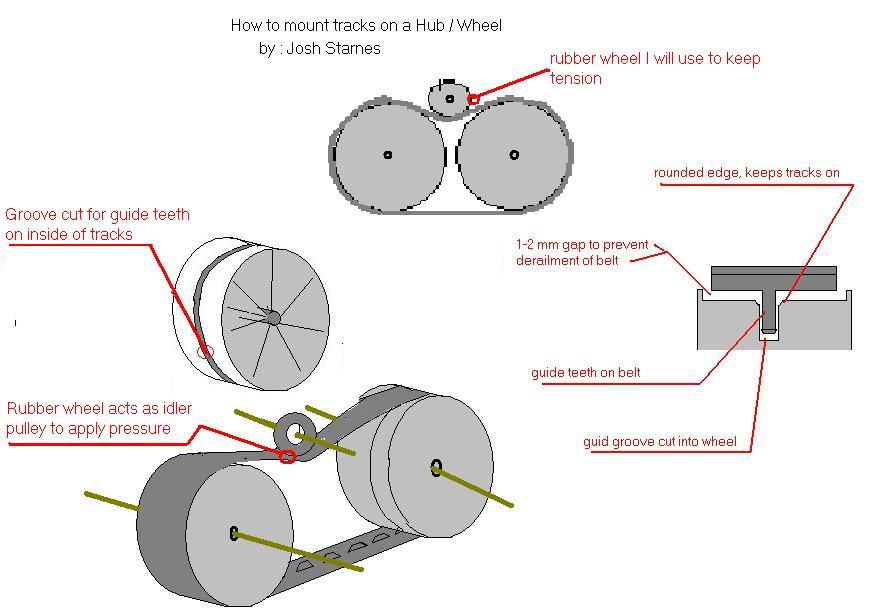
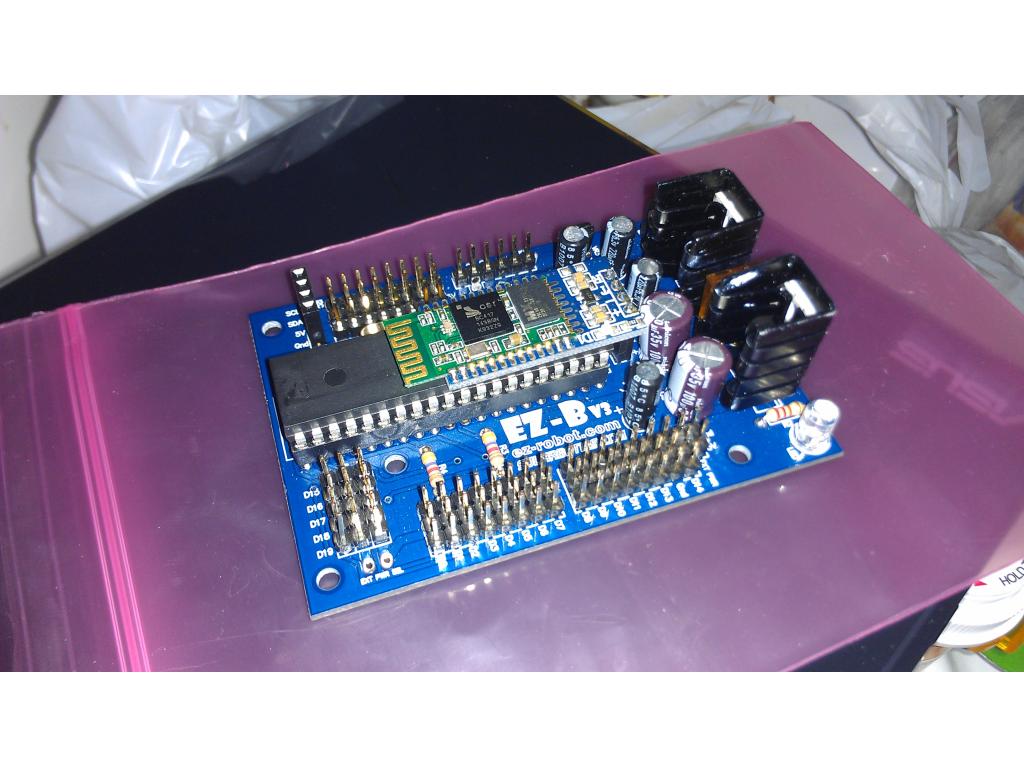
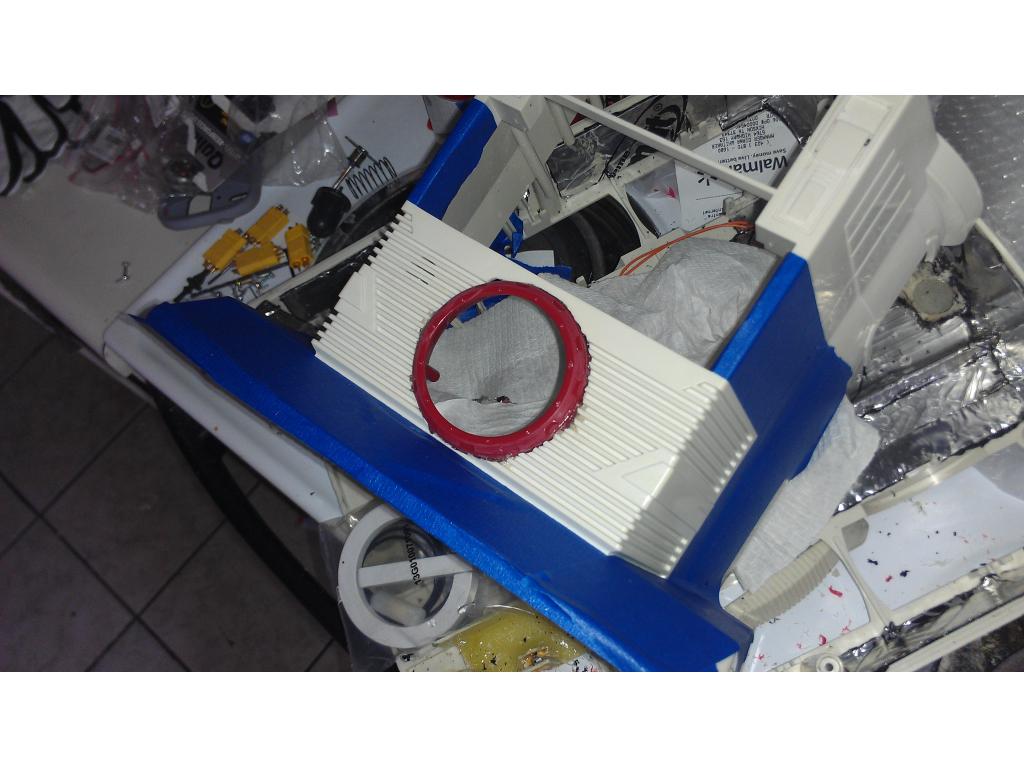
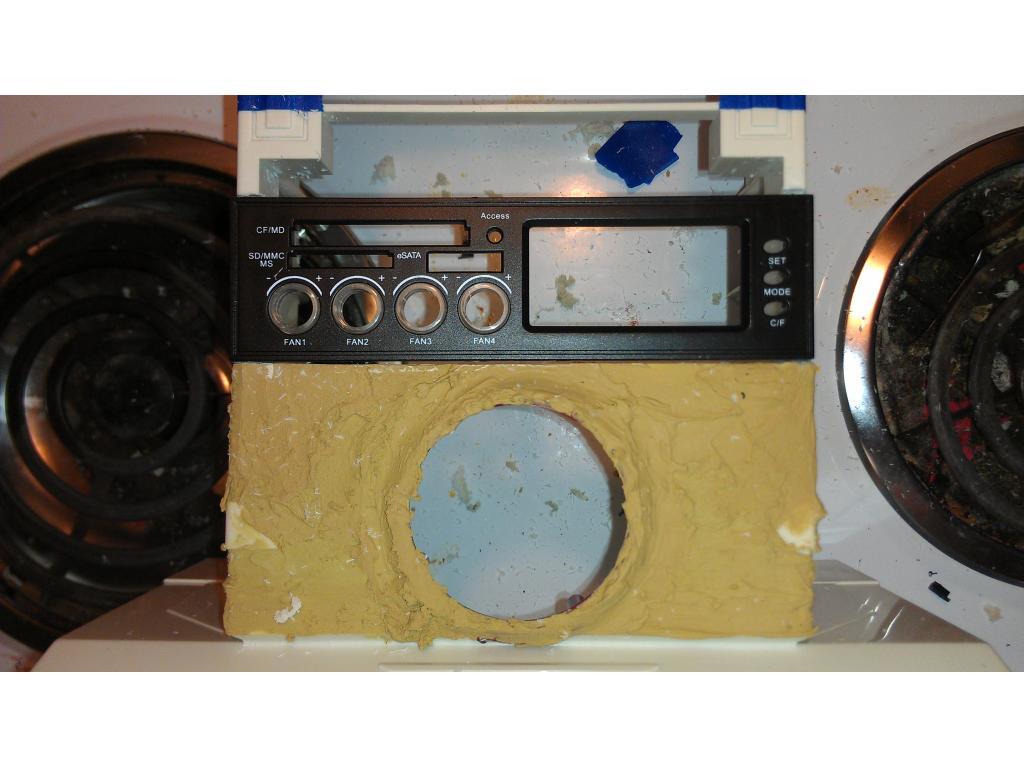
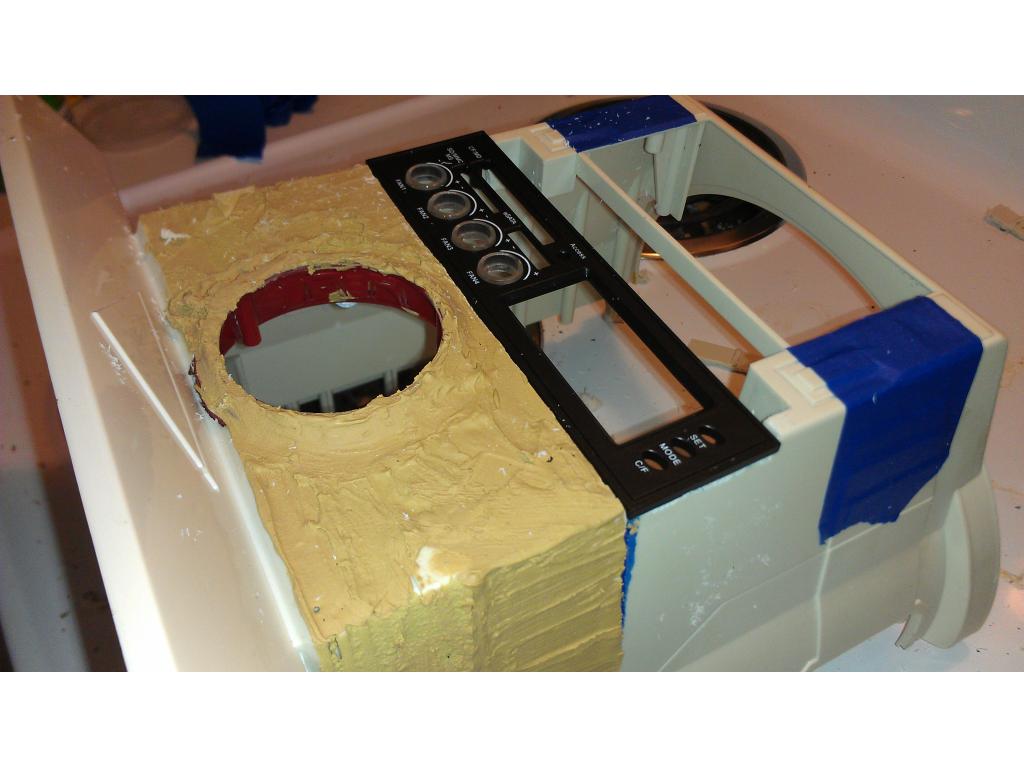
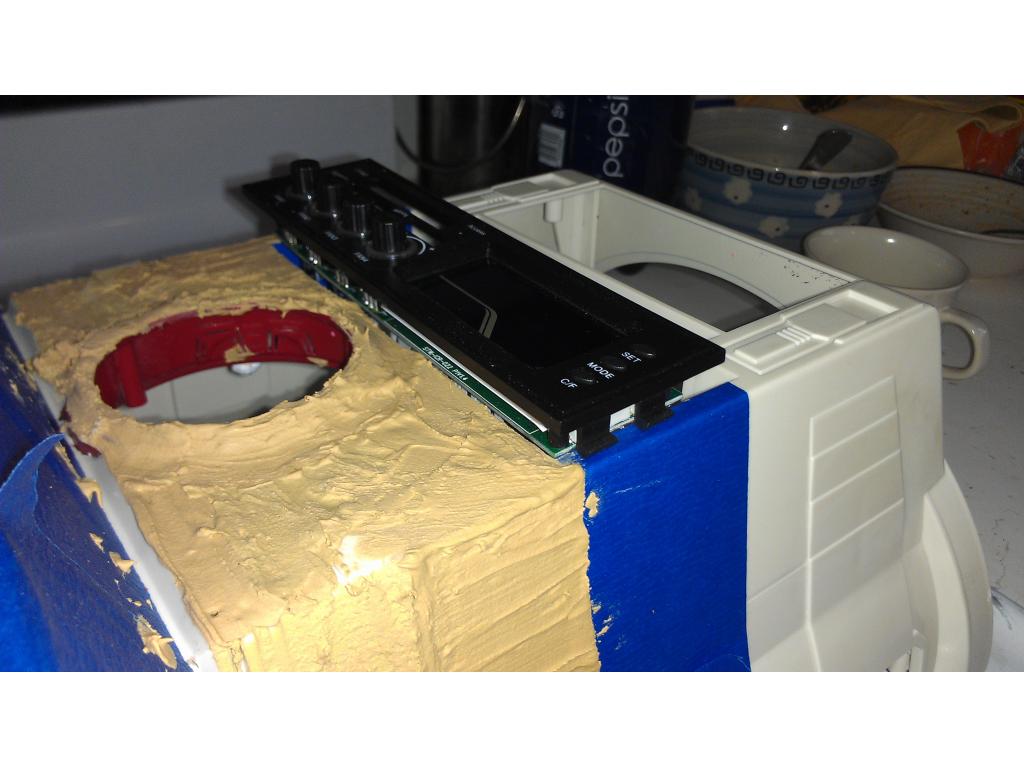
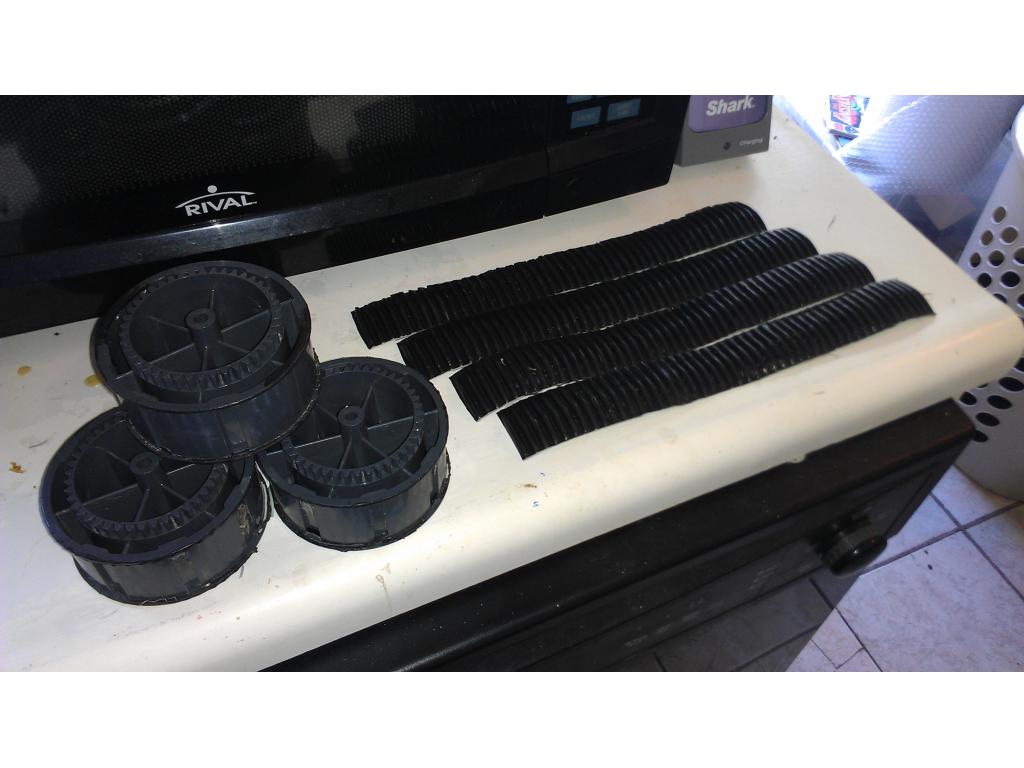
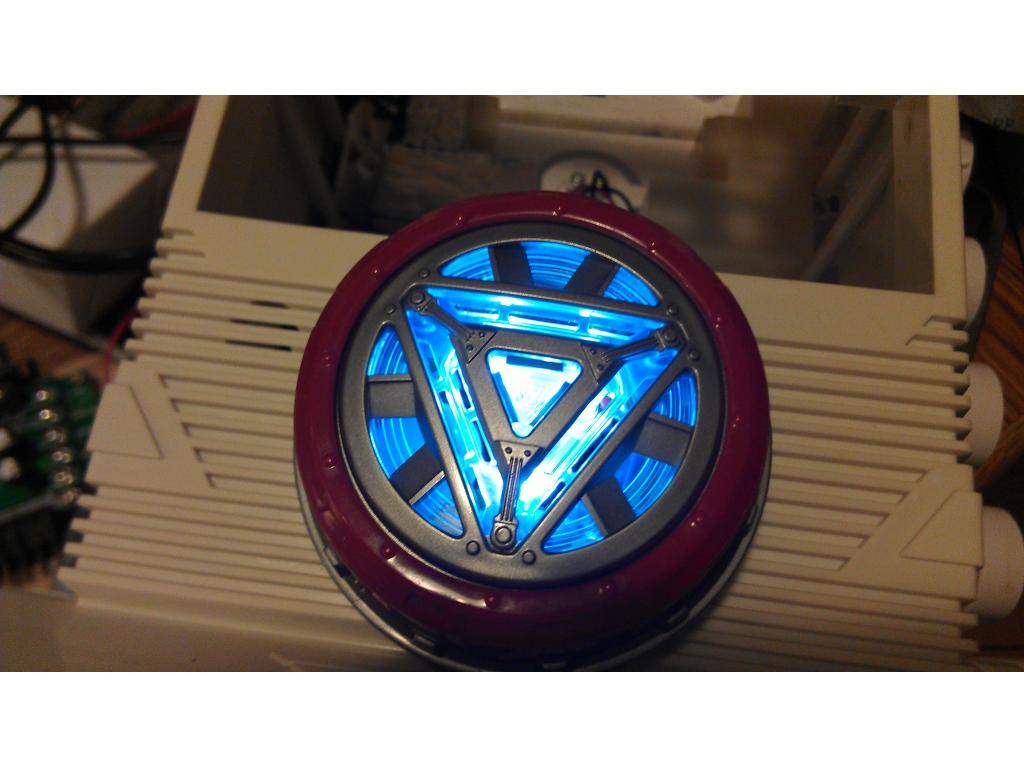
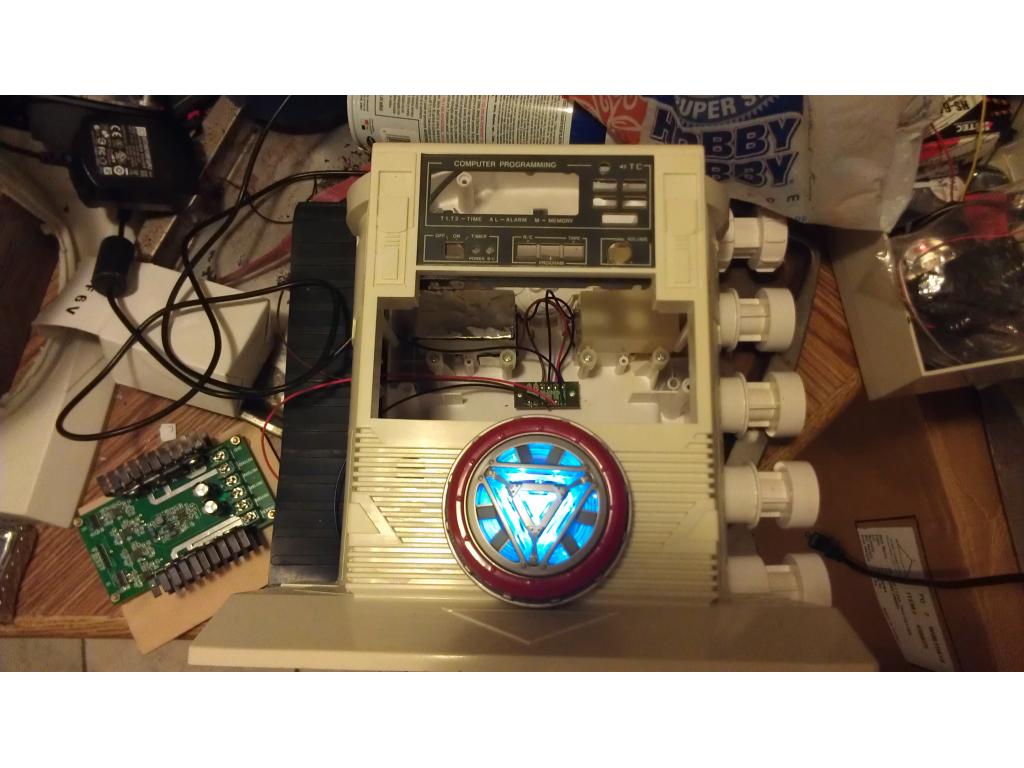
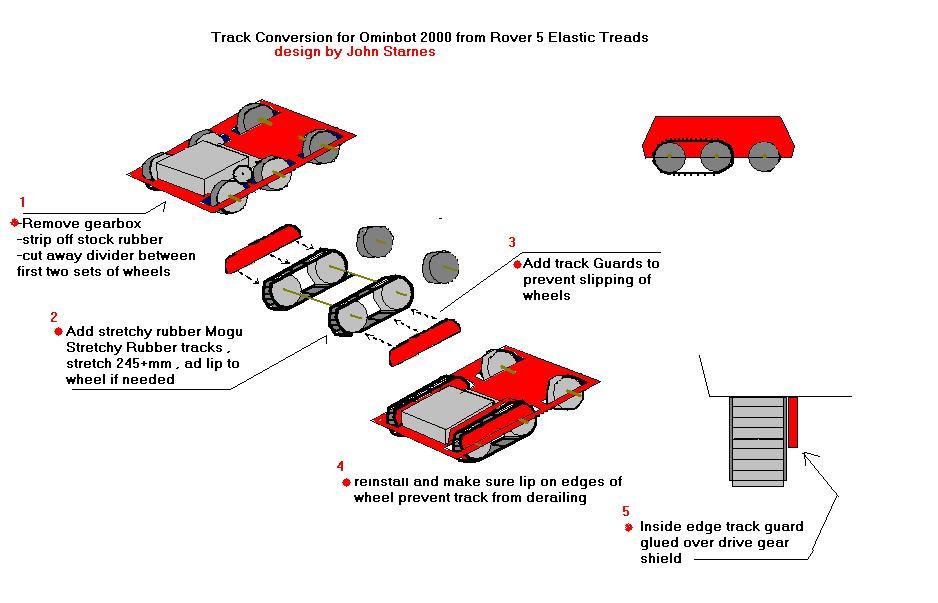
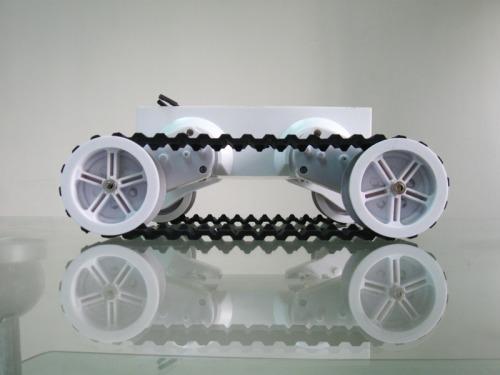
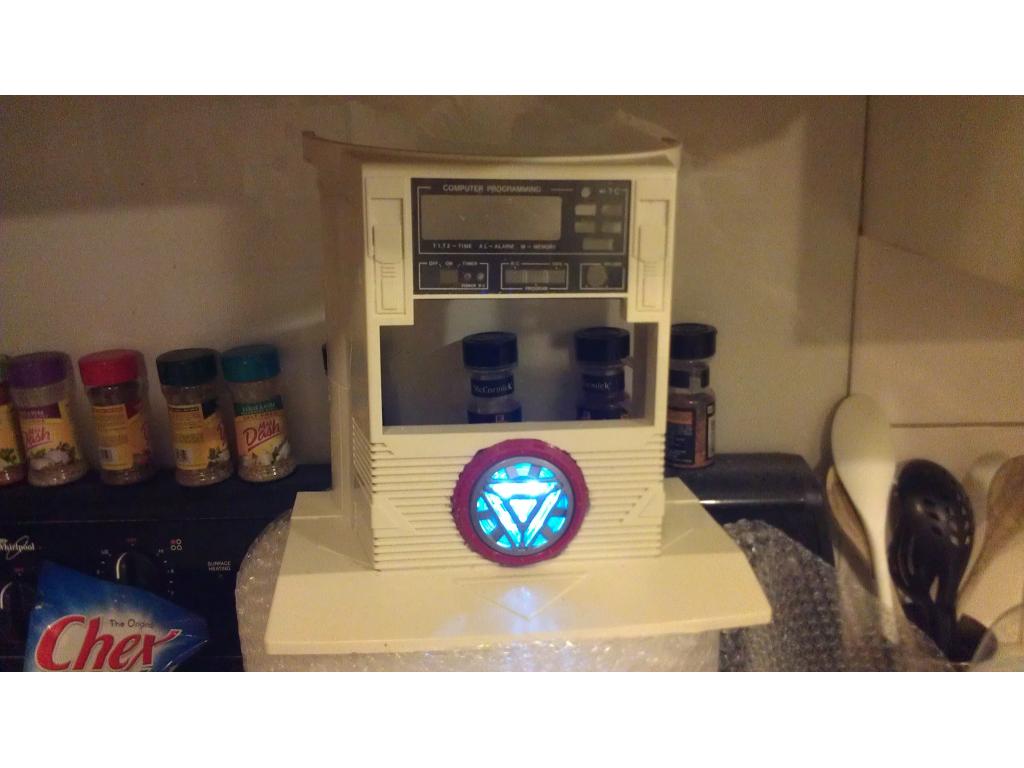
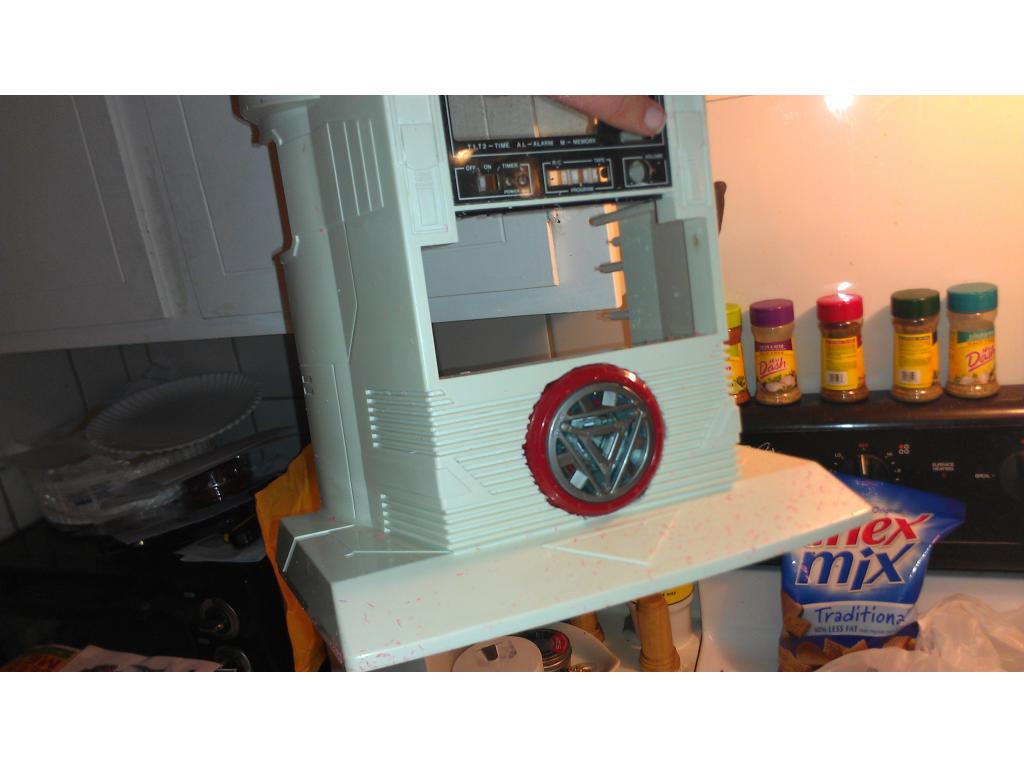
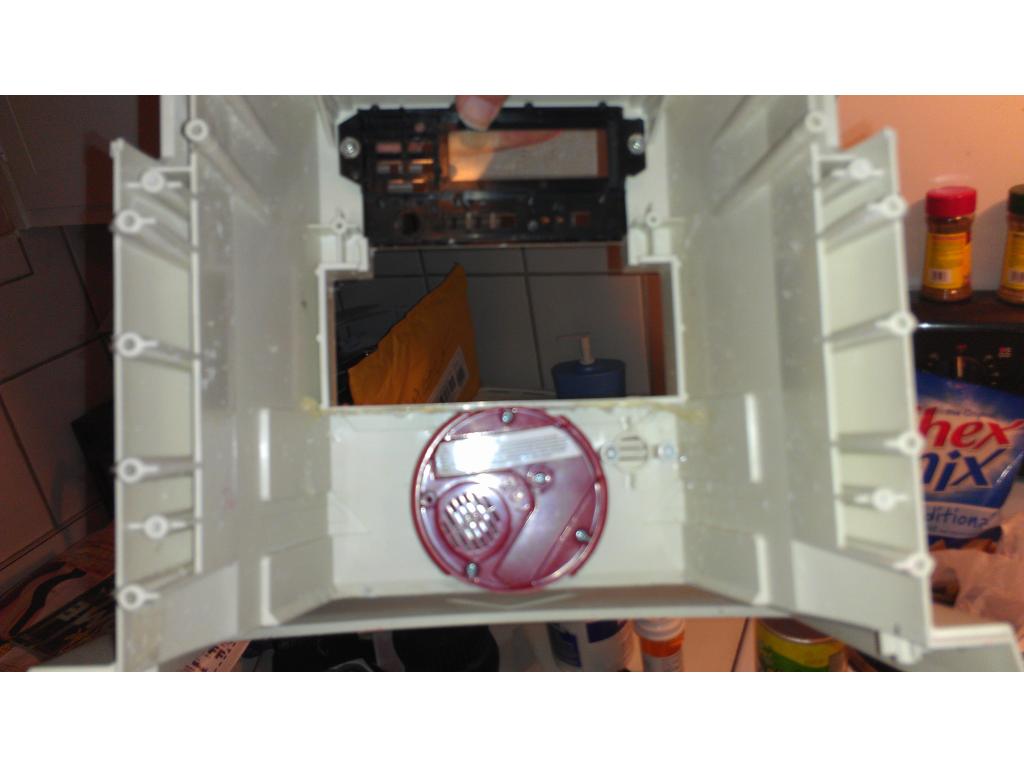
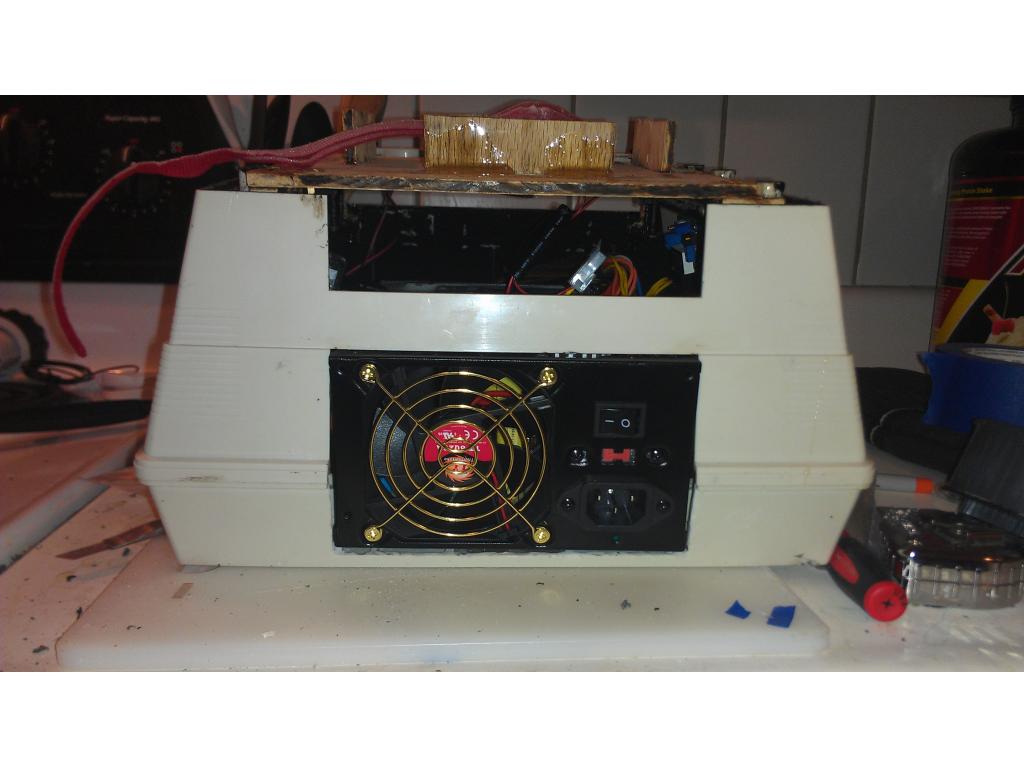
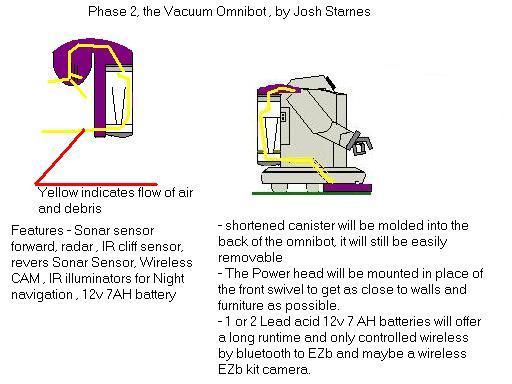
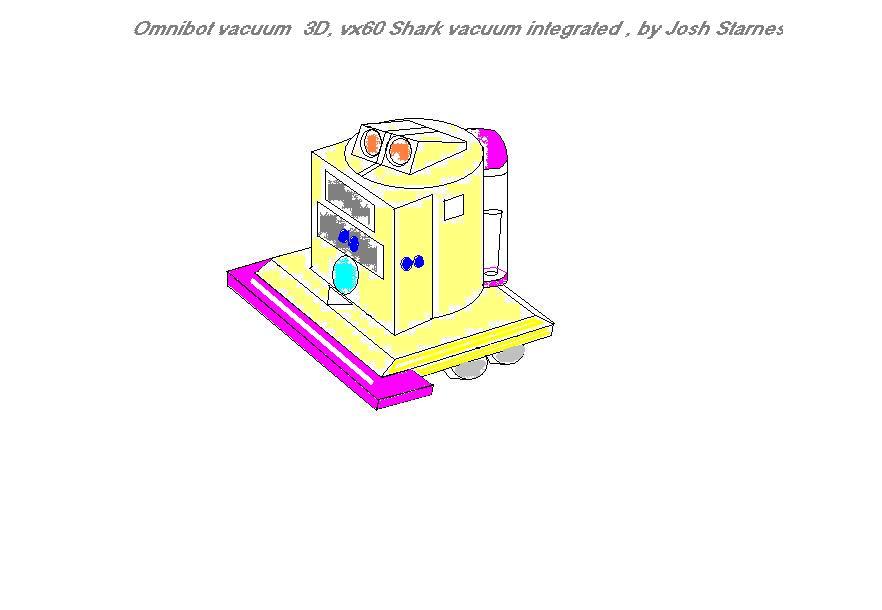
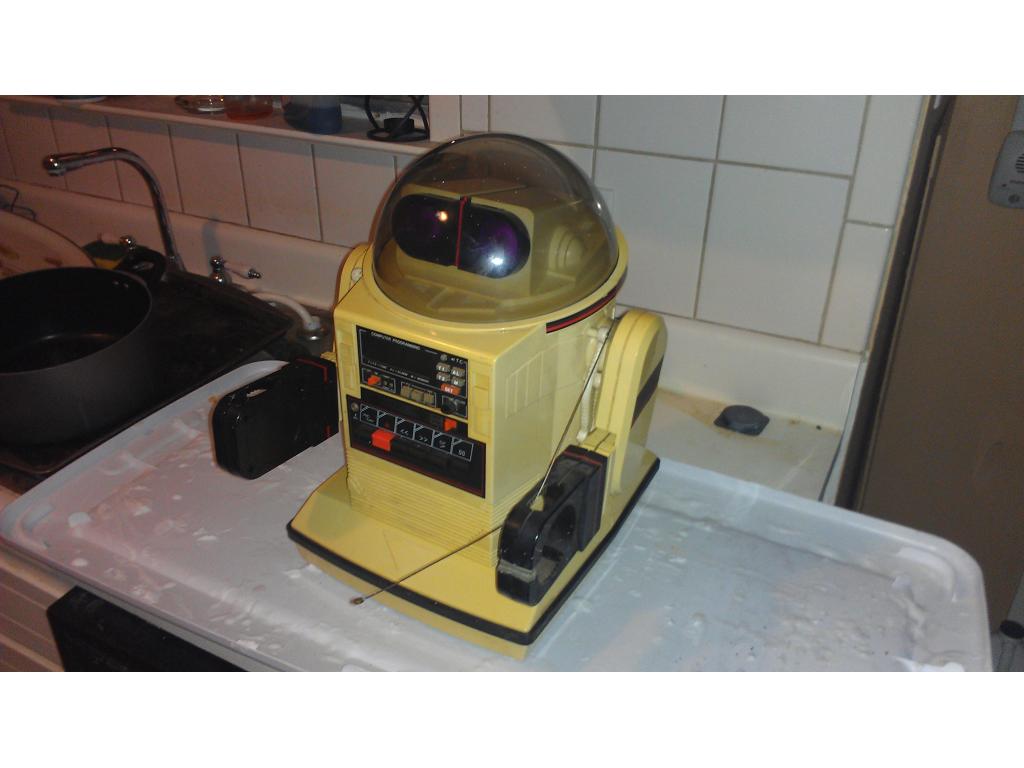
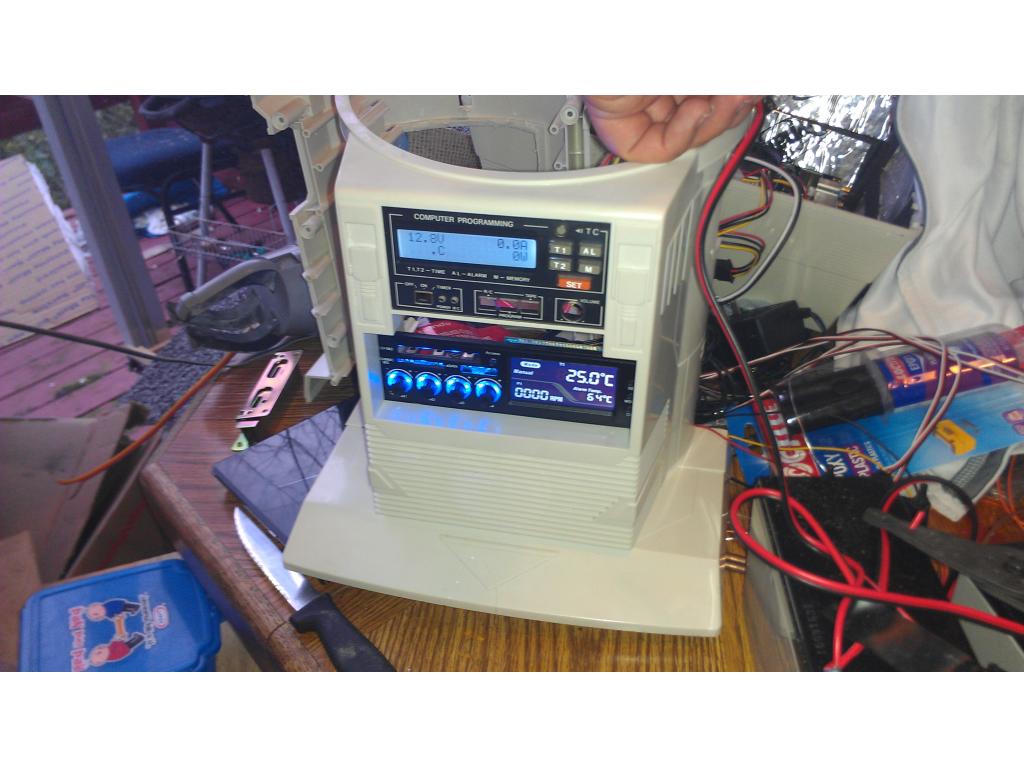
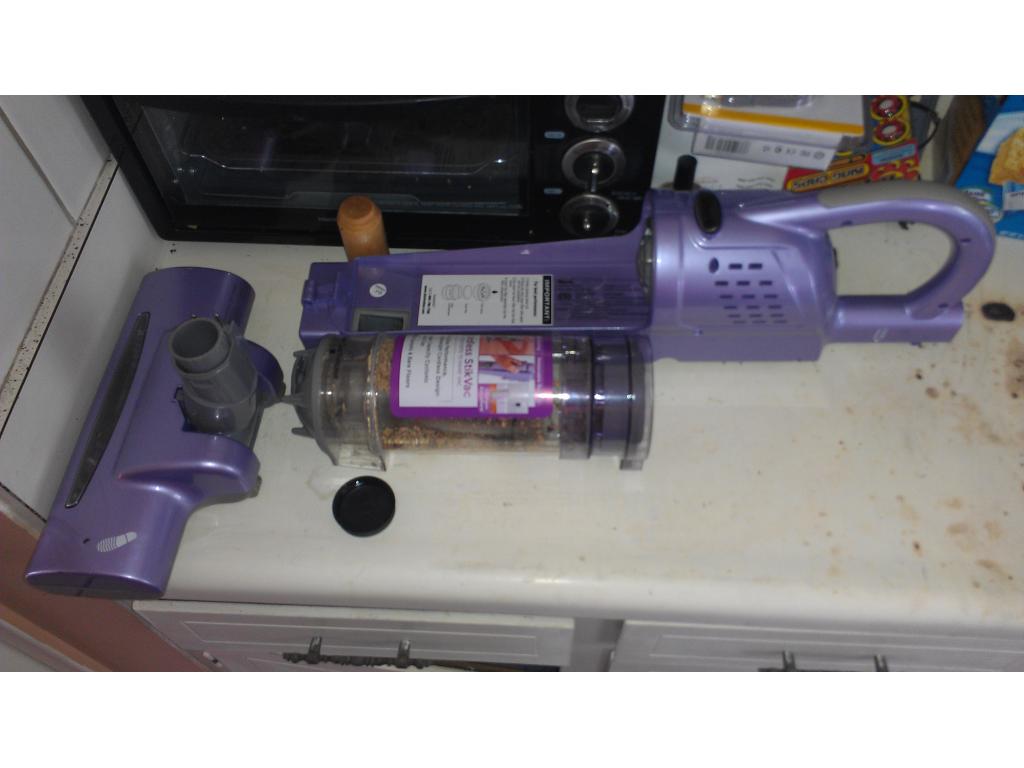
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.

By jstarne1
— Last update

Discover more robots
Deleted's Erne - Emotive Robot
ERNE emotive robot studies human-robot interaction: 10 micro servos for facial animation, 2 head servos, EZ-Robot...
Mickey666maus's Oled Animated Eyes For ARC Pro And ARC Free
Control ItsyBitsy M4 OLED eyes from Synthiam ARC via serial: flash firmware, send animation numbers over COM ports and...
Ericez's Droid For Theater Robot Contest
Build low-cost BB-8 and R2-D2 Star Wars robots from PVC water pipe and control them using an EZ-Board.

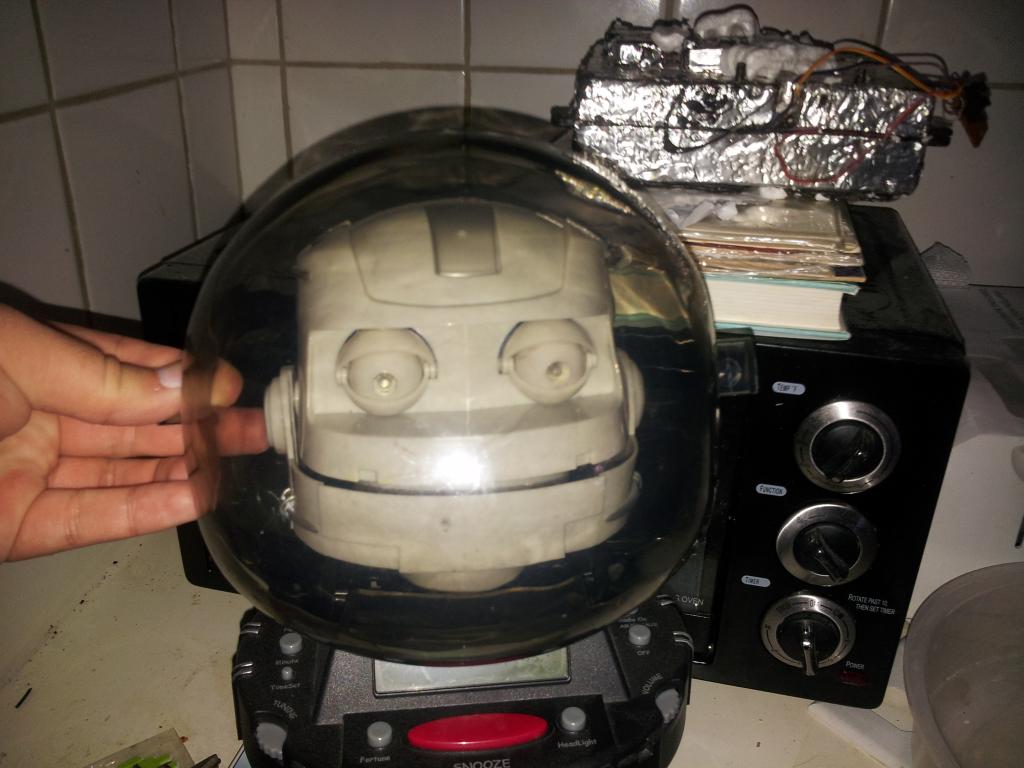
Ok.I'm pretty sure over the shoulder is a no go because the head is so wide you would need something to wrap around from.the back , the vacuum will take up most available room so.doing it as a arm sounds.better.
i guess ime to make his head bigger lol
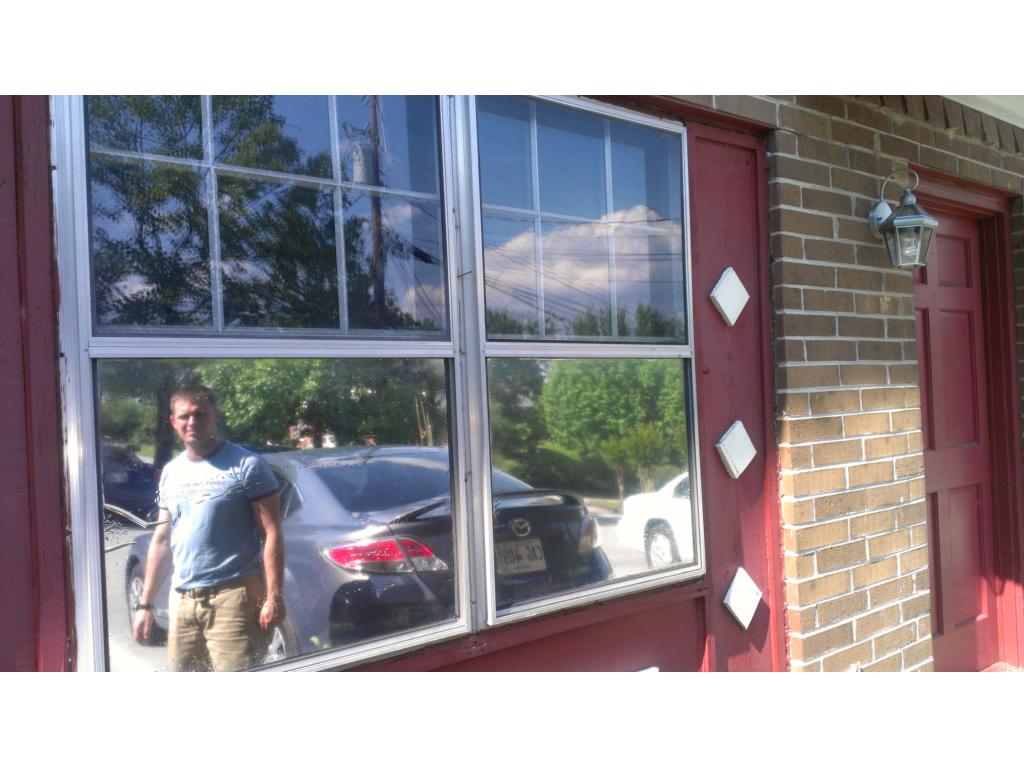
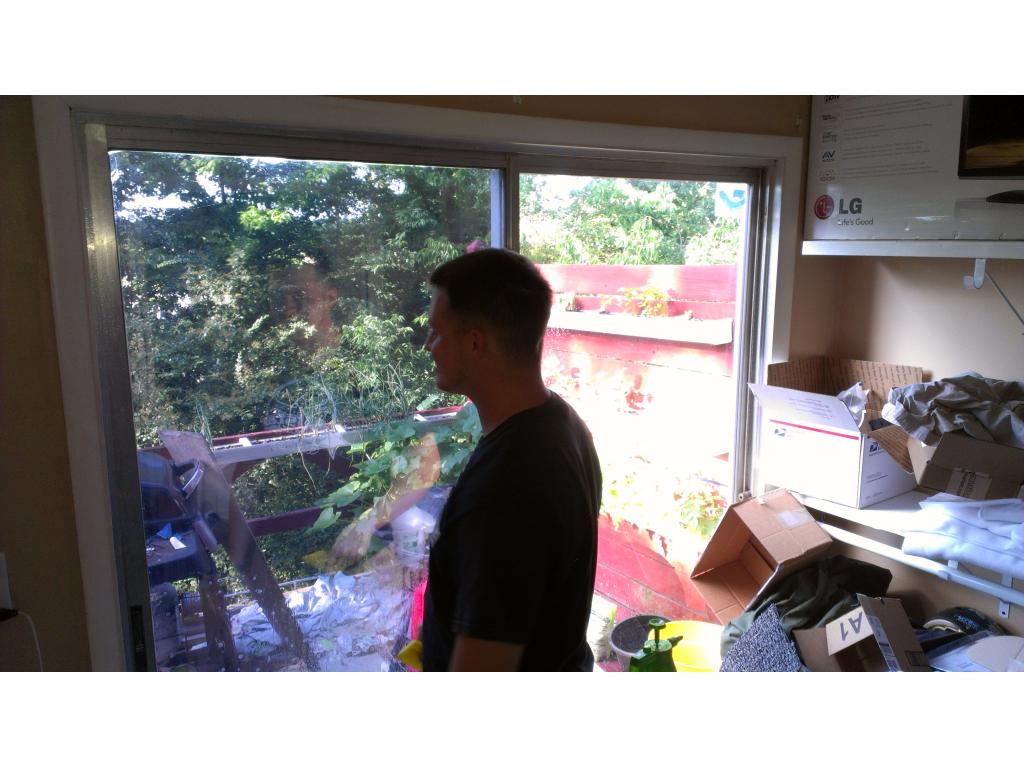
Ok so to move forward progress I need to start working on the project in daylight hours. Soo my roommate brought home tint and we applied heat rejection ceramic tint to the sliding glass doors and on the front 40% tint on the inside glass and chrome metalized tint on the outside glass... I immediately noticed the temp dropped and reduced the blinding light that use to come through the 7 foot tall windows.

Tinted on.left vs not on.the right. Take in mind the camera adjusts the brightness , in real life the difference is more dramatic. Now that the temps should be dropped tommorow it should be acceptable and comfortable to work on the project in during the day. Otherwise I would wait till after midnight when it cools off to work on anythingis the that the camera that comes with EZB looks blurry a little,can tell by the boxes on the right,i use logitech HD camera
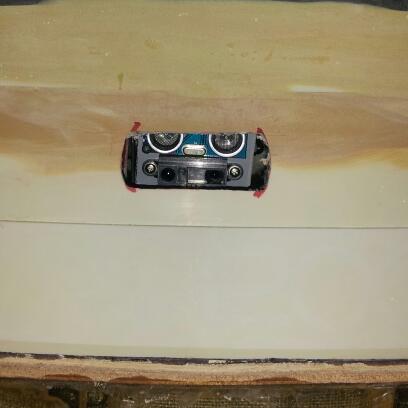
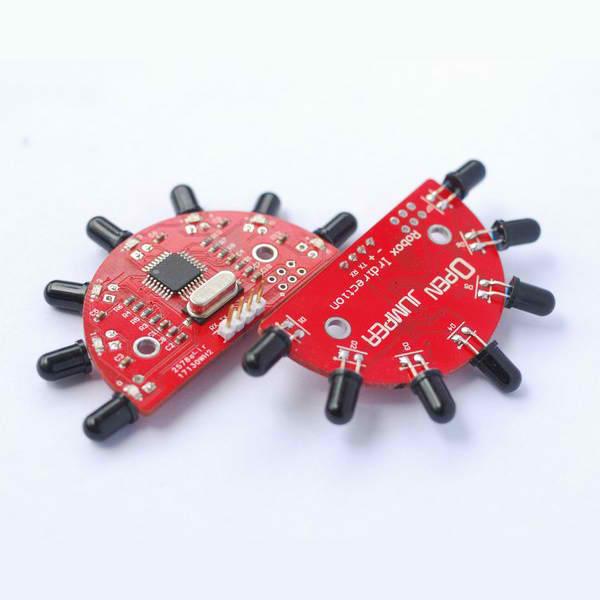
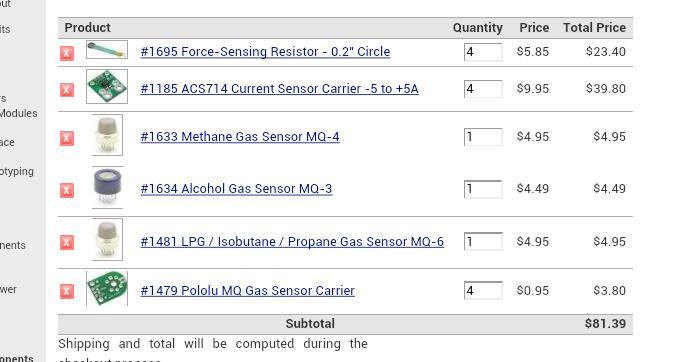
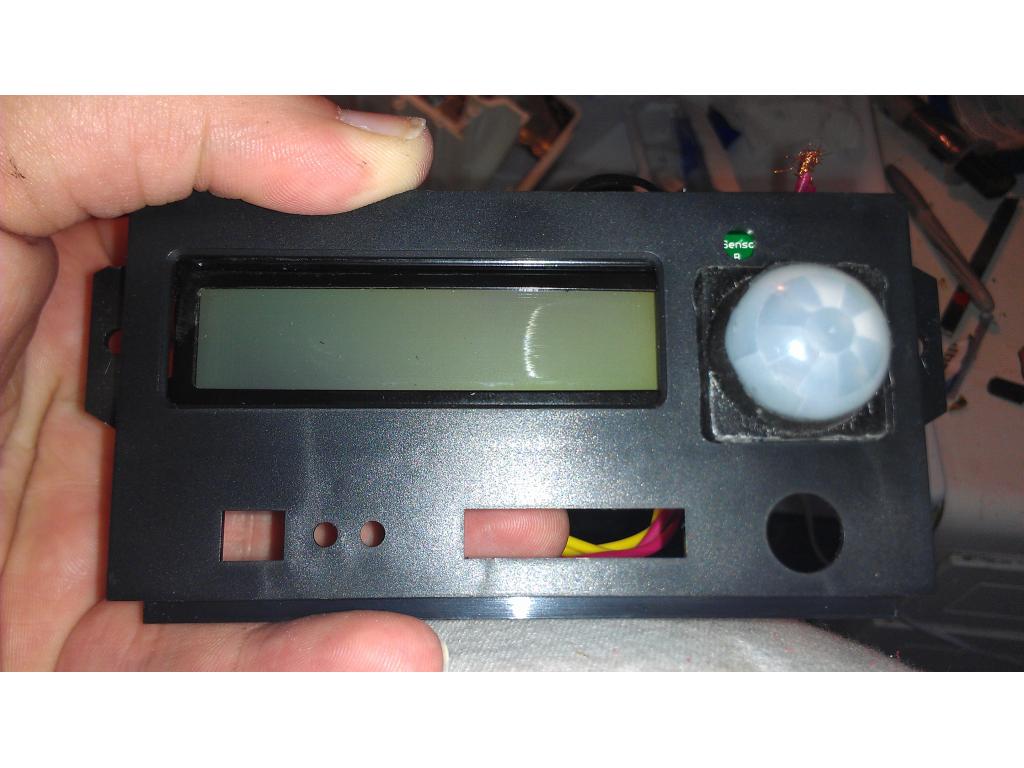
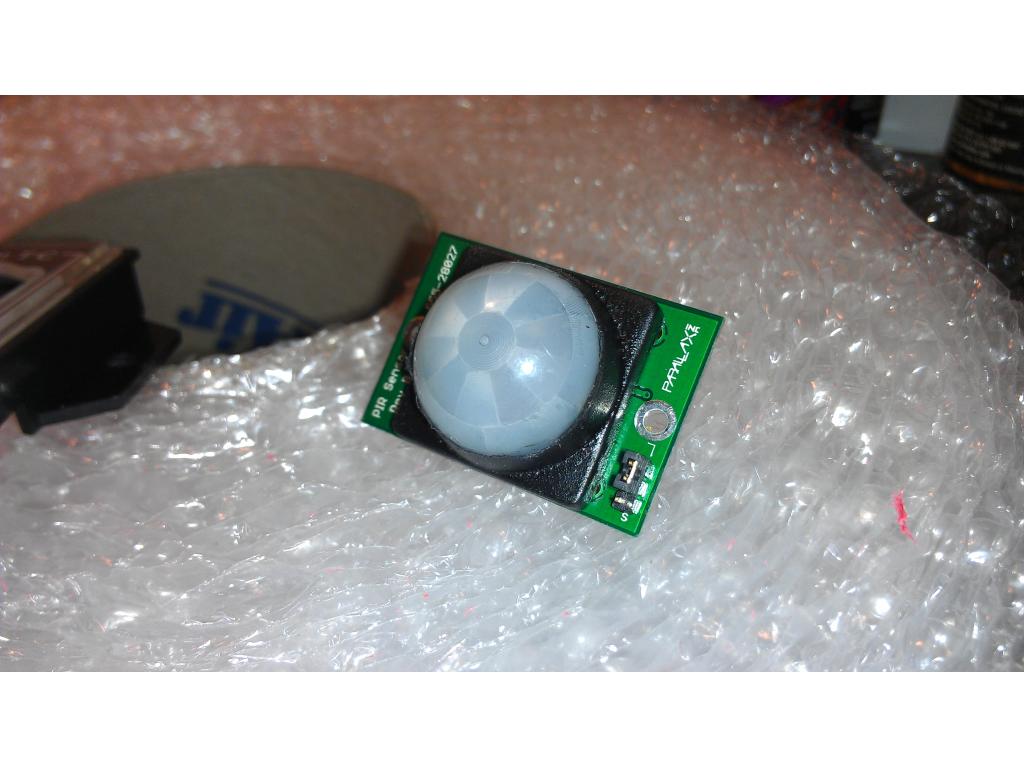
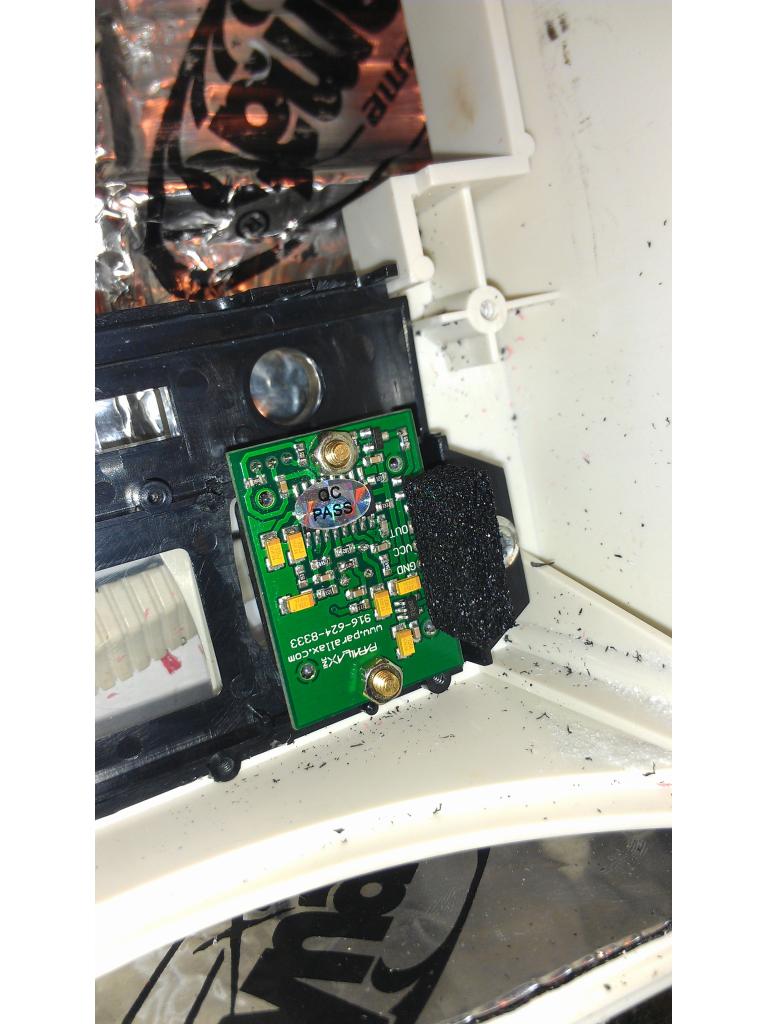
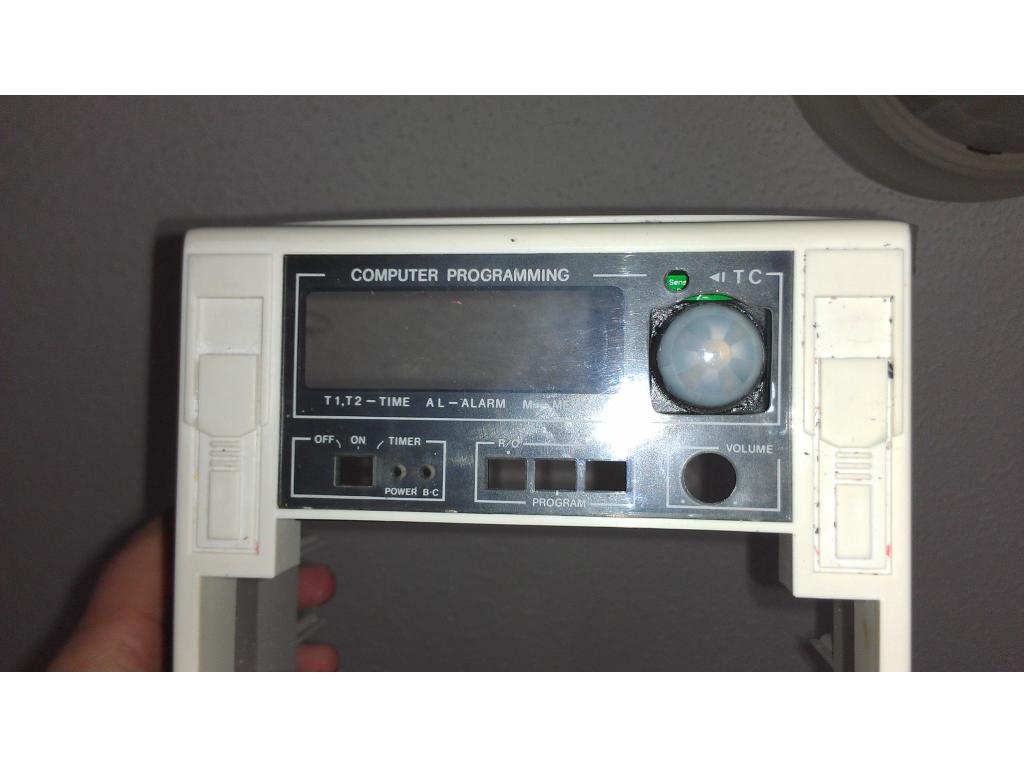
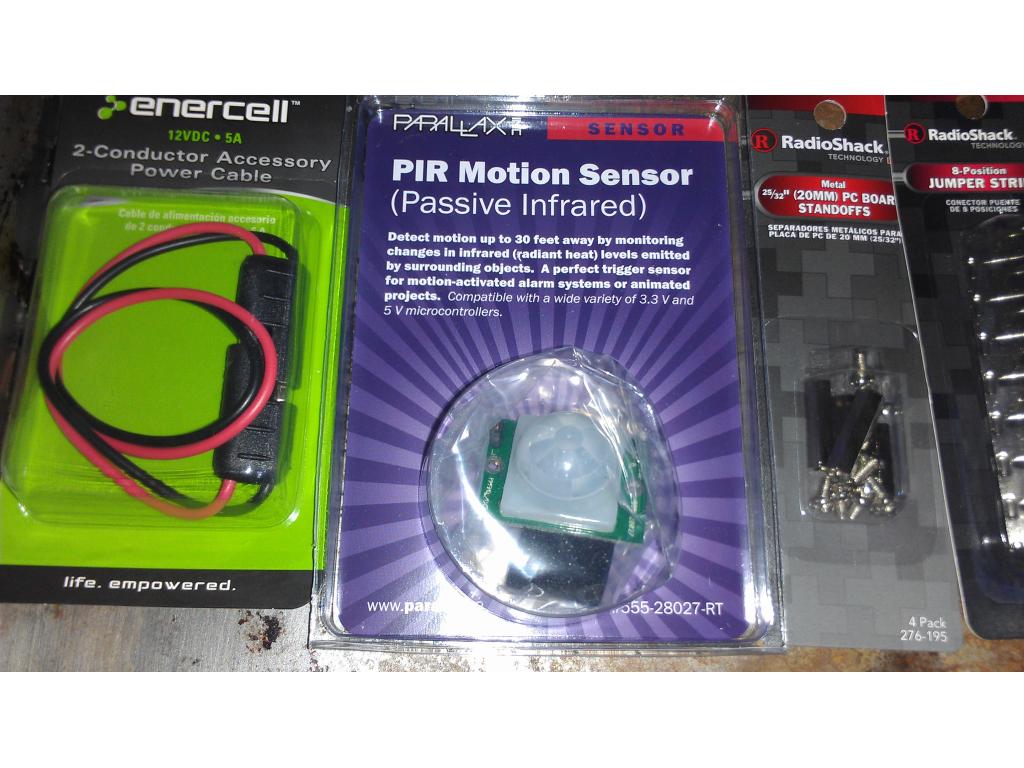
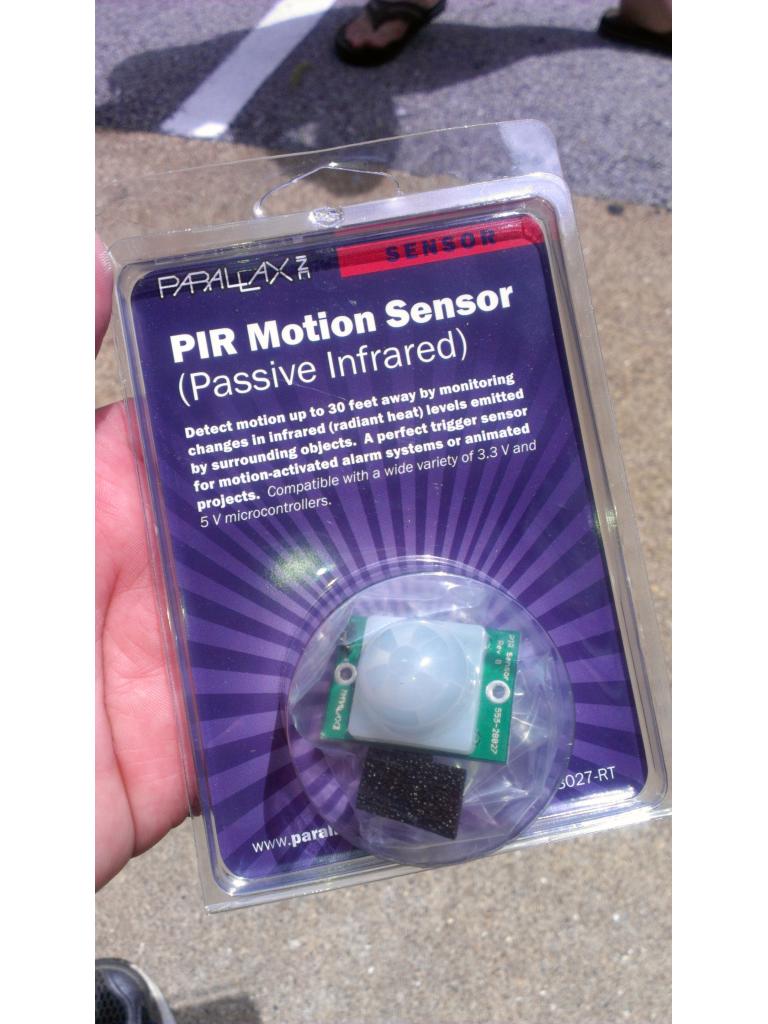
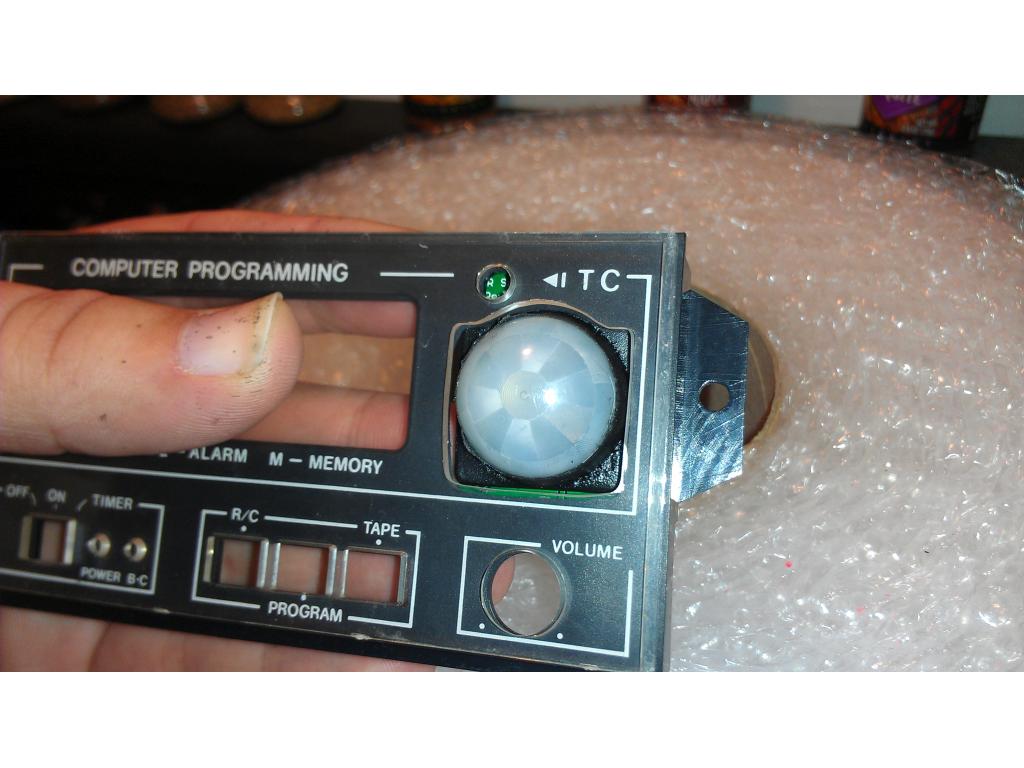
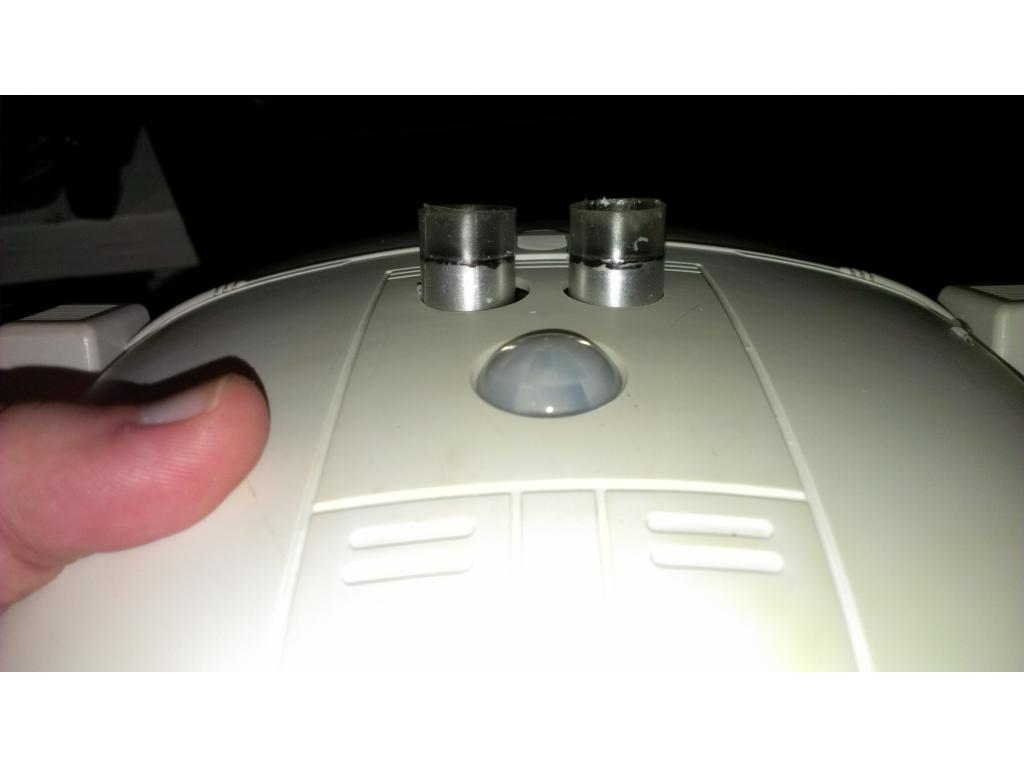
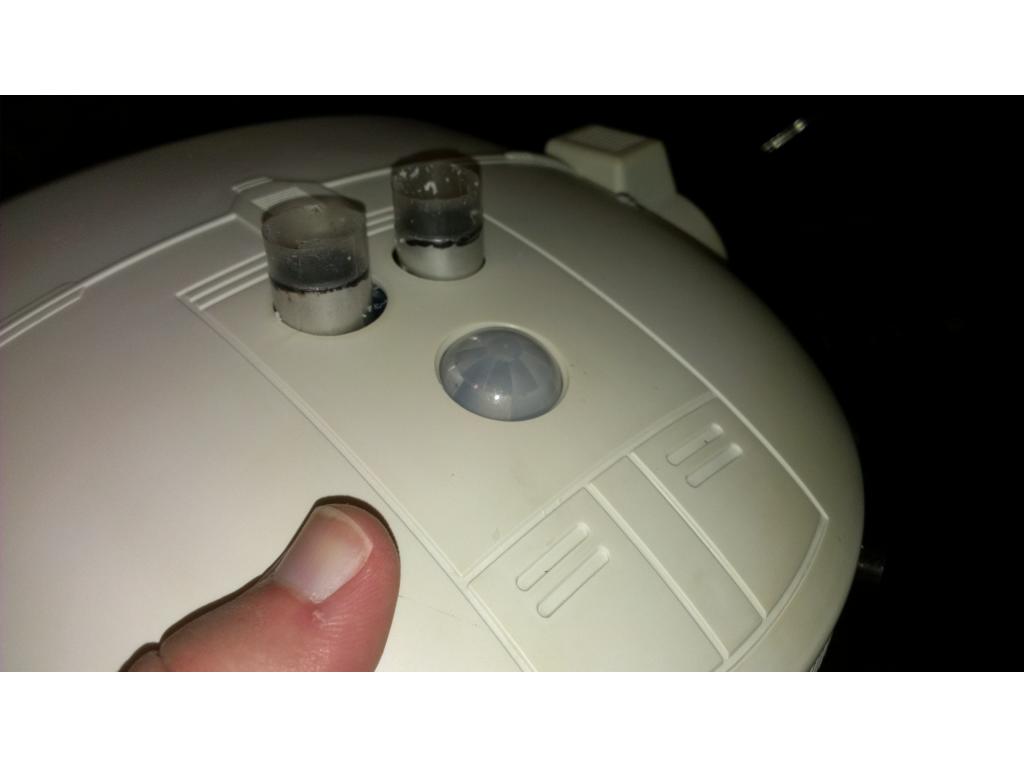
Ok I picked up 3 PIR Sensors to build into my robot so it has 360 degrees detection. Also I picked up.three laser modules.
Where will you mount those? Left, right and back? Webcam for front detection?
I would have total of 4 , front back side to side
JOSH if looking for a good source for the EZB camera for your omnibot robots check my post on getting the same camera EZB uses for a lot less,and takes the same amount of time in shipping too