cE9s4PsOgeBQIORwjd5!~~60_1-634818020230156250.jpg)
Lupuc4g~~60_35-634706297915000000.jpg)
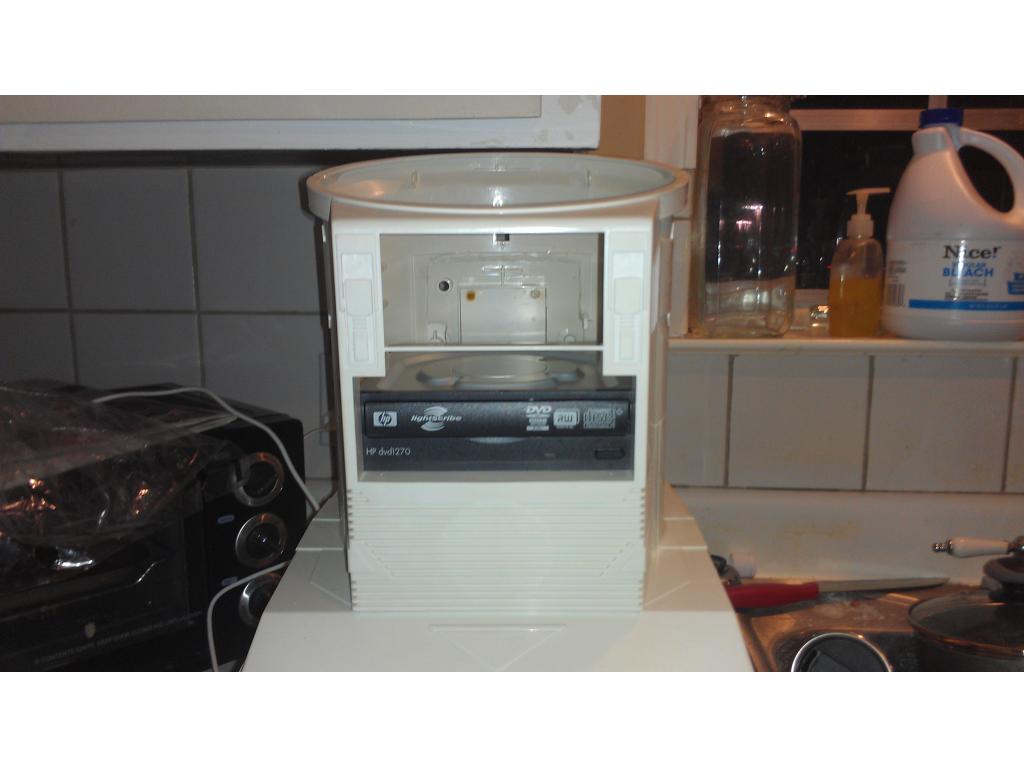
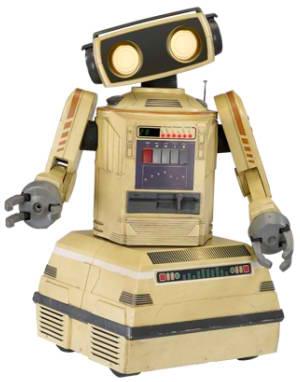
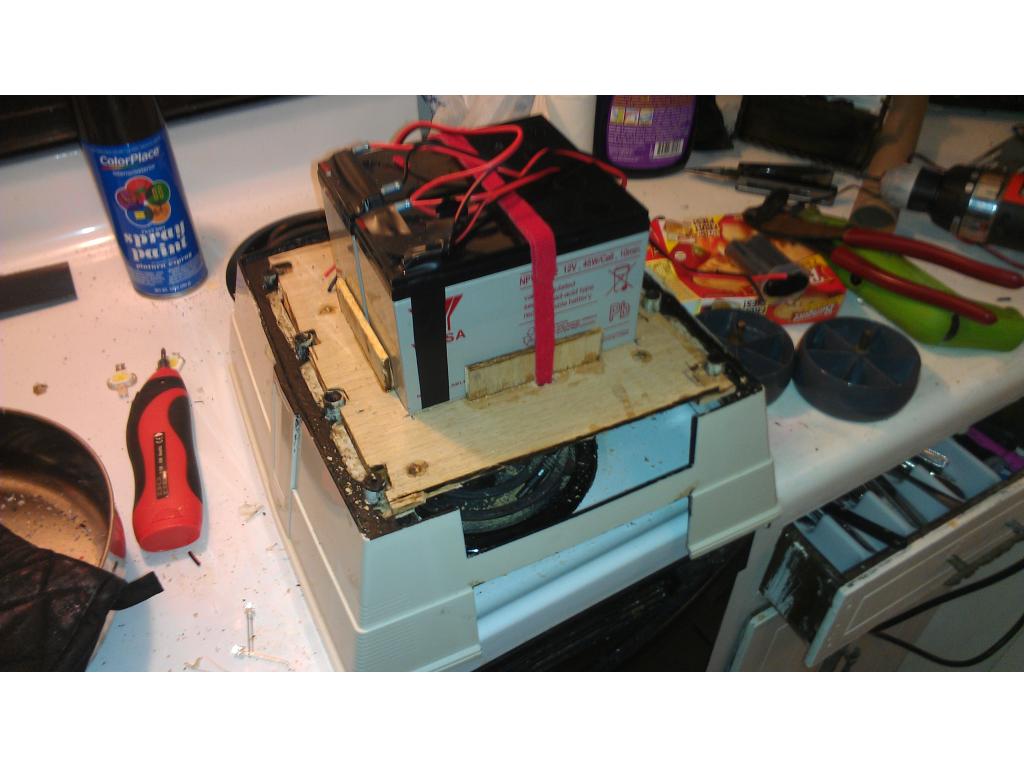
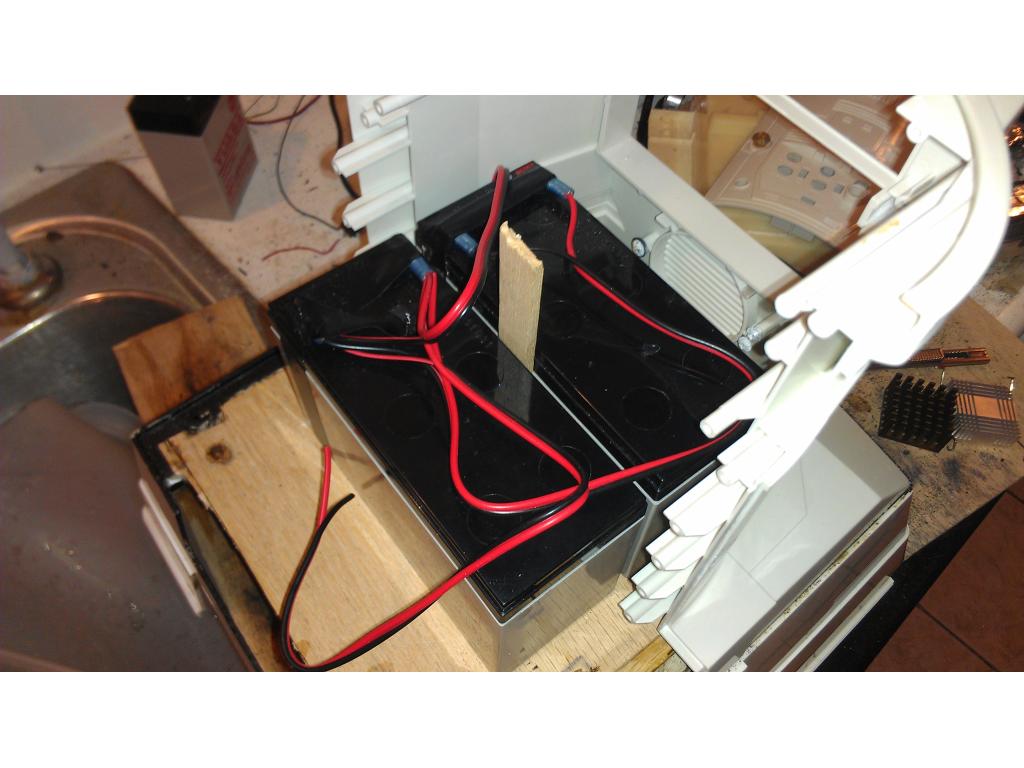
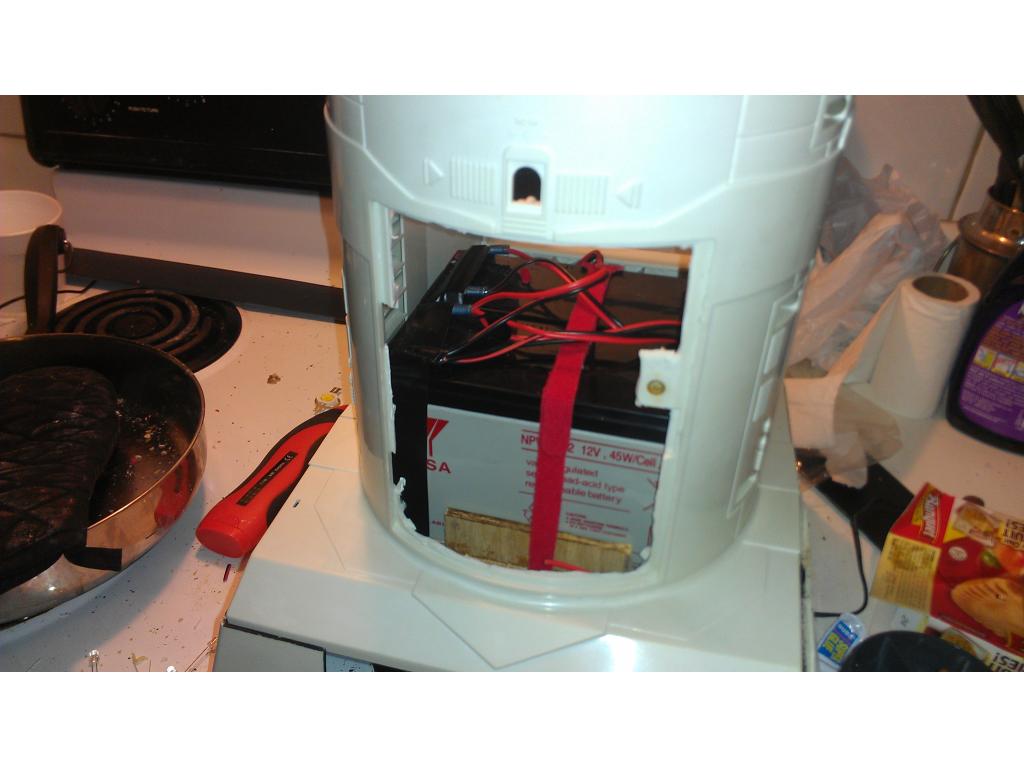
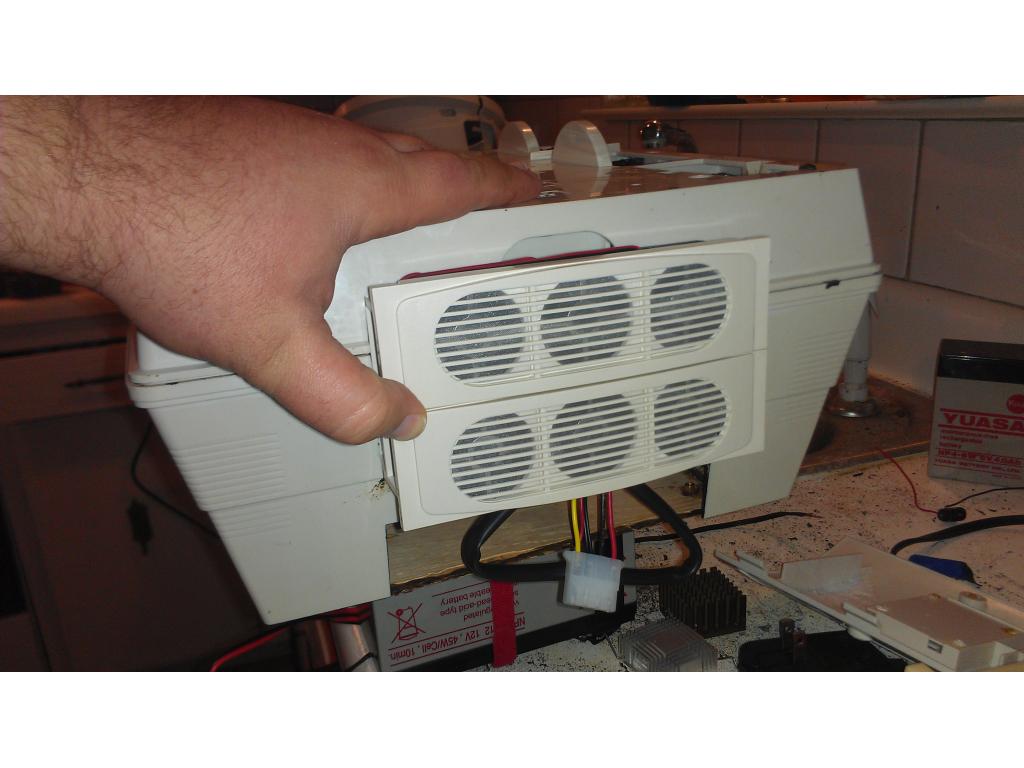
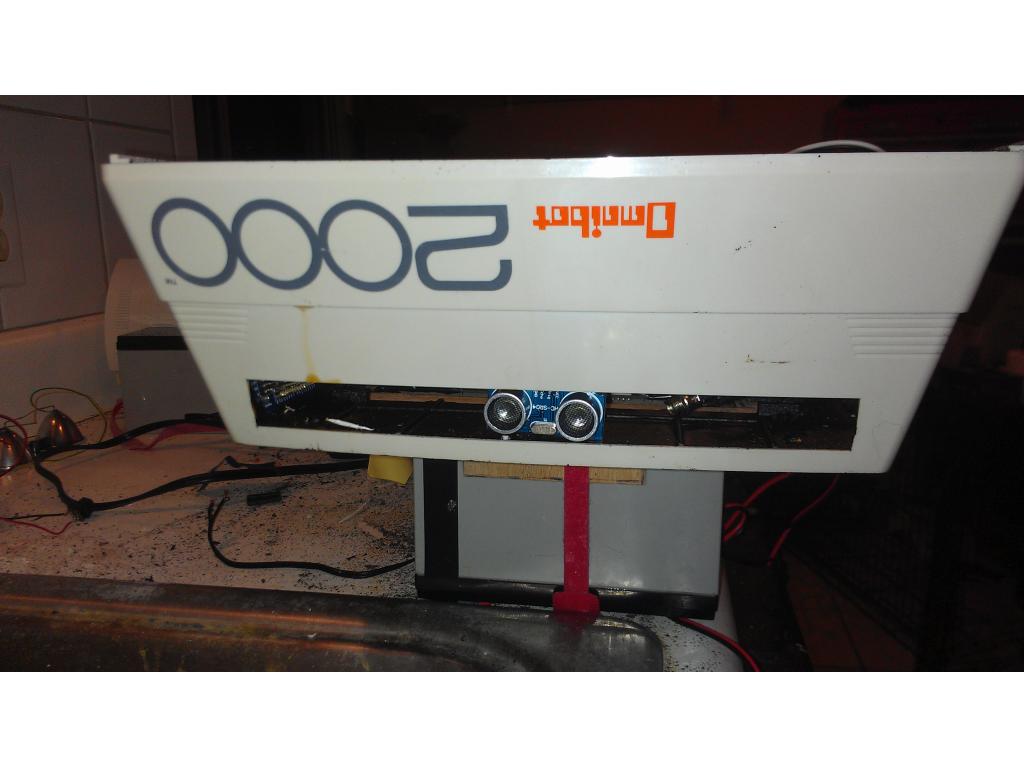
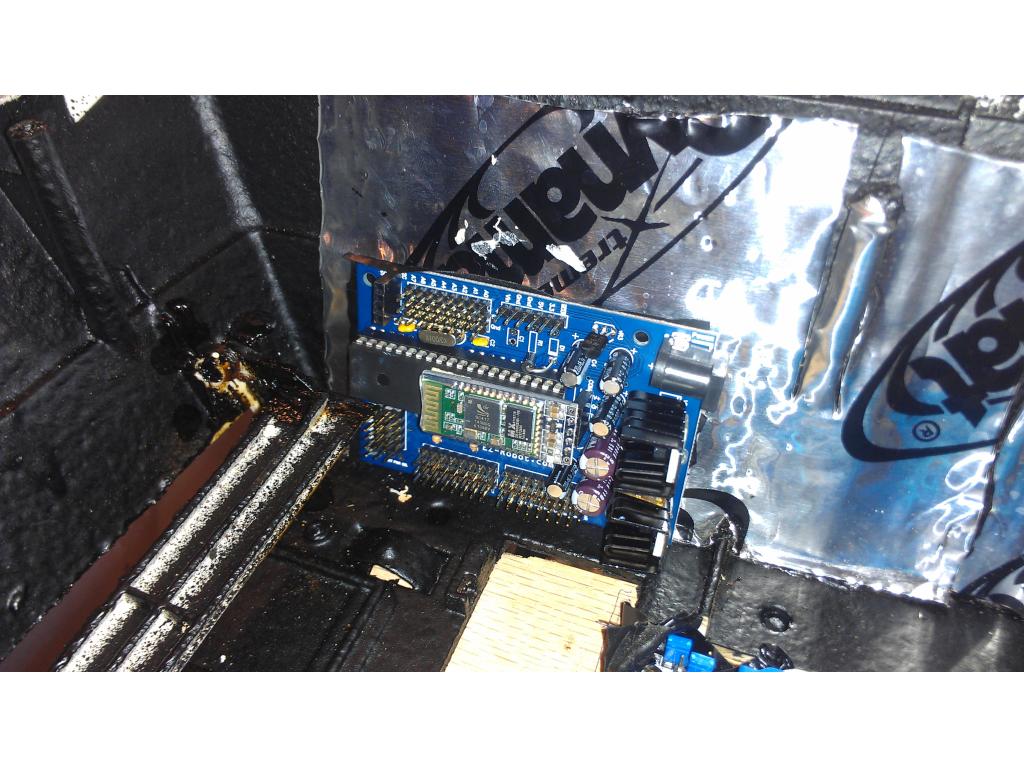
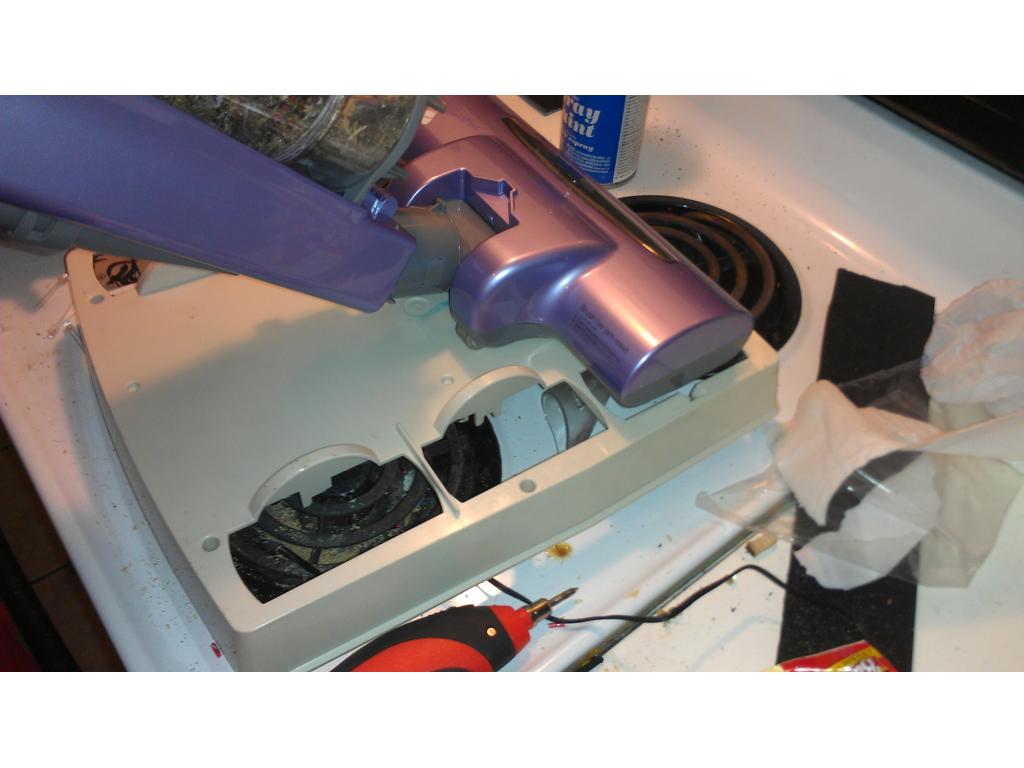
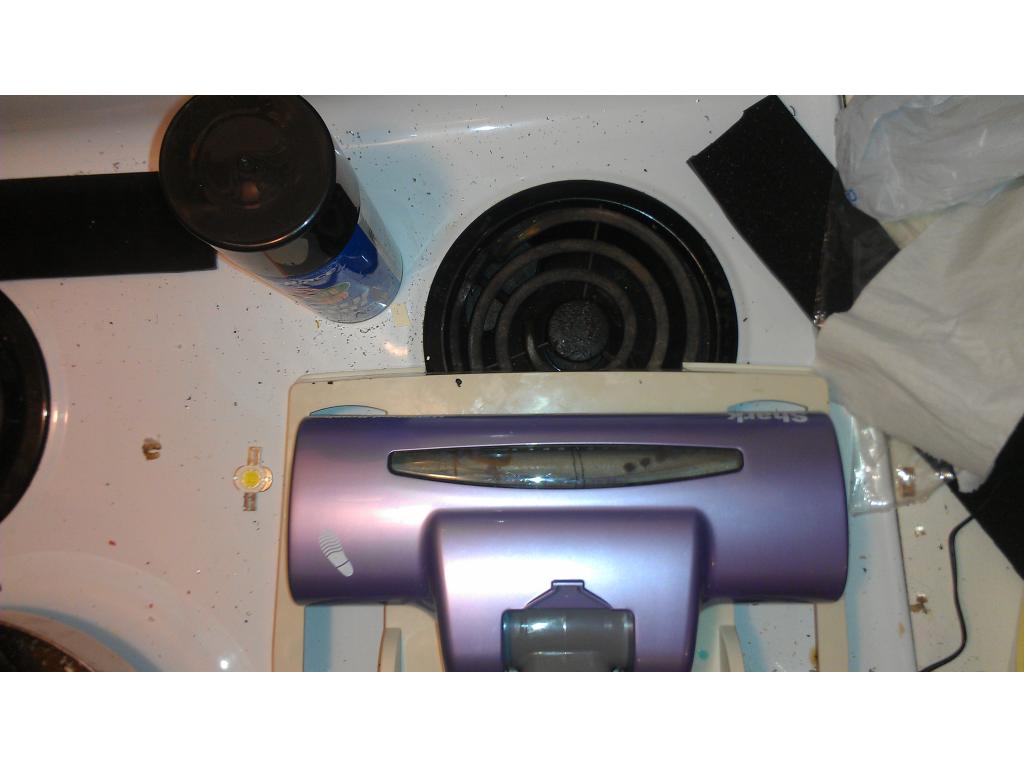
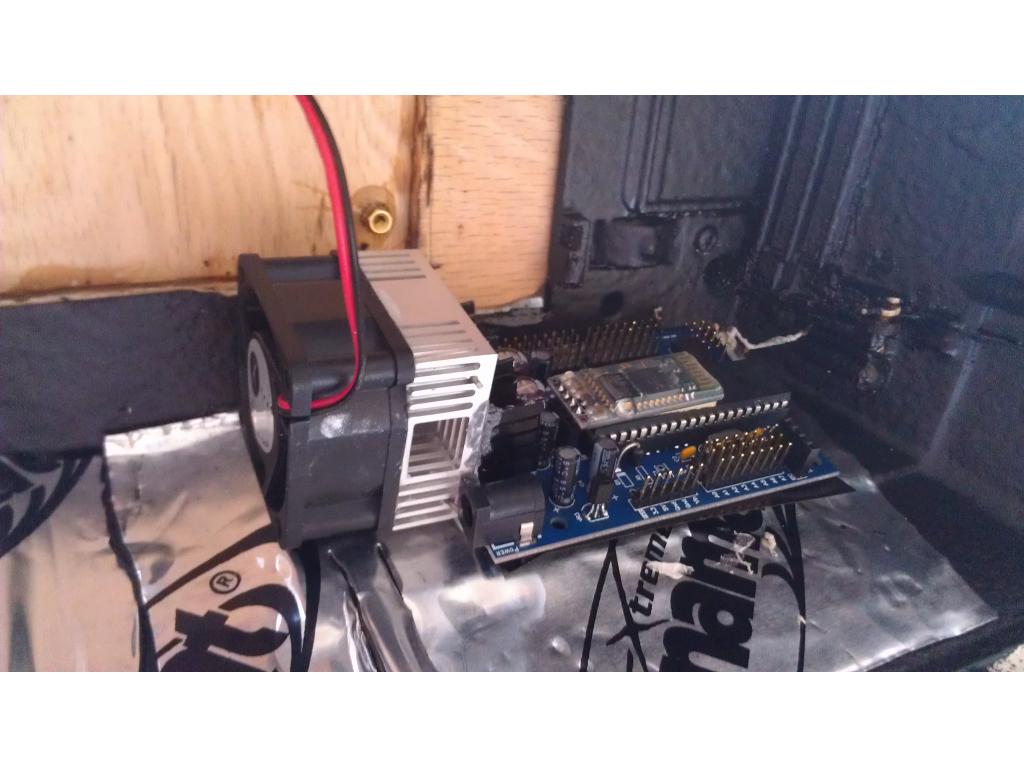
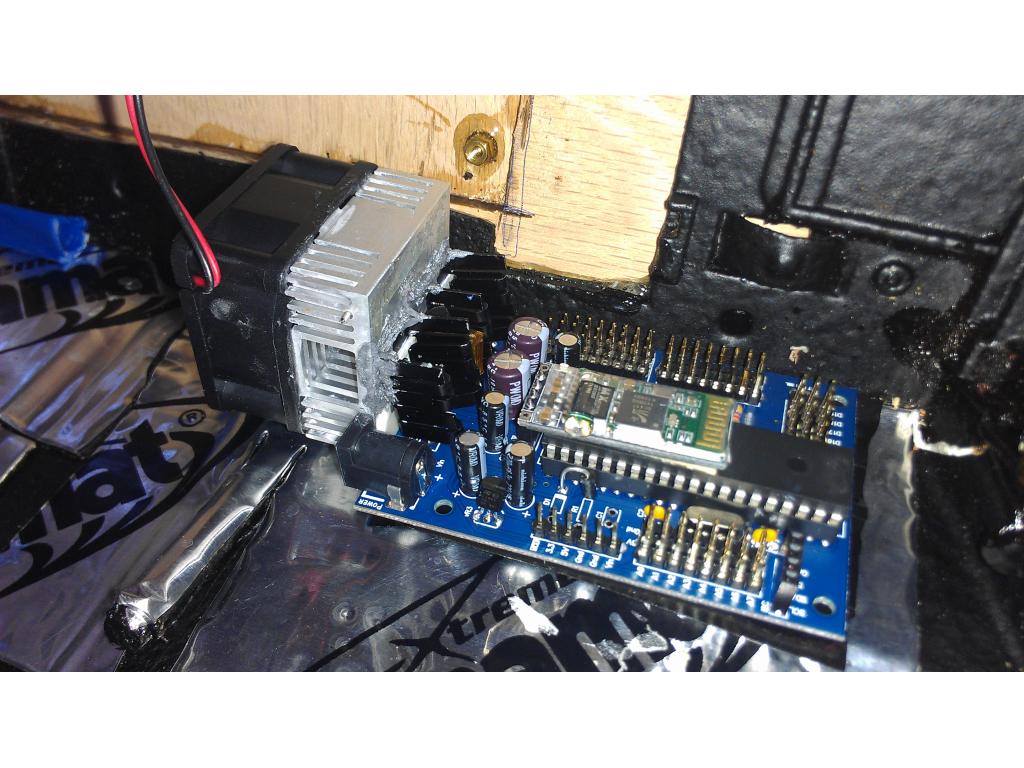
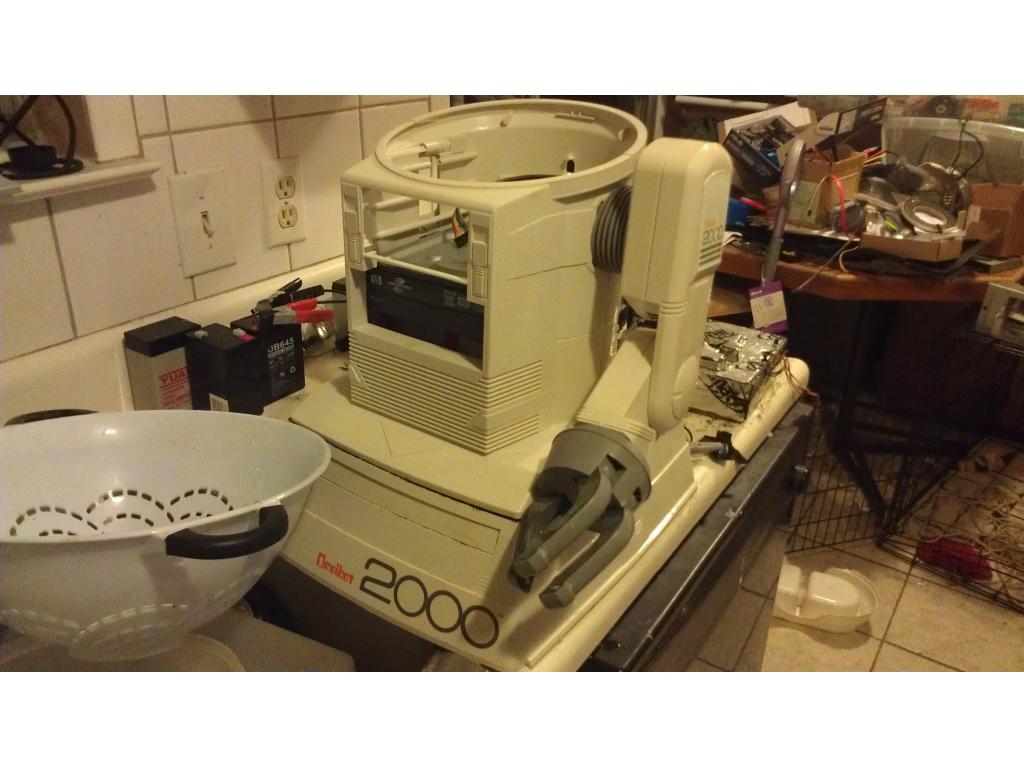
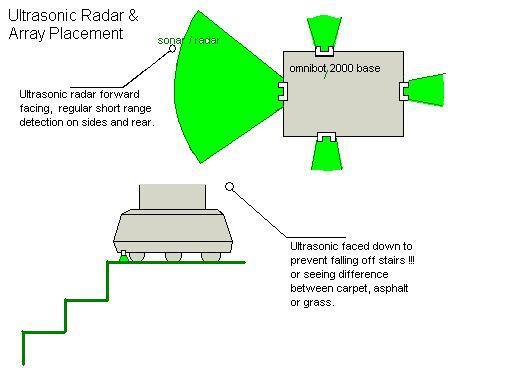
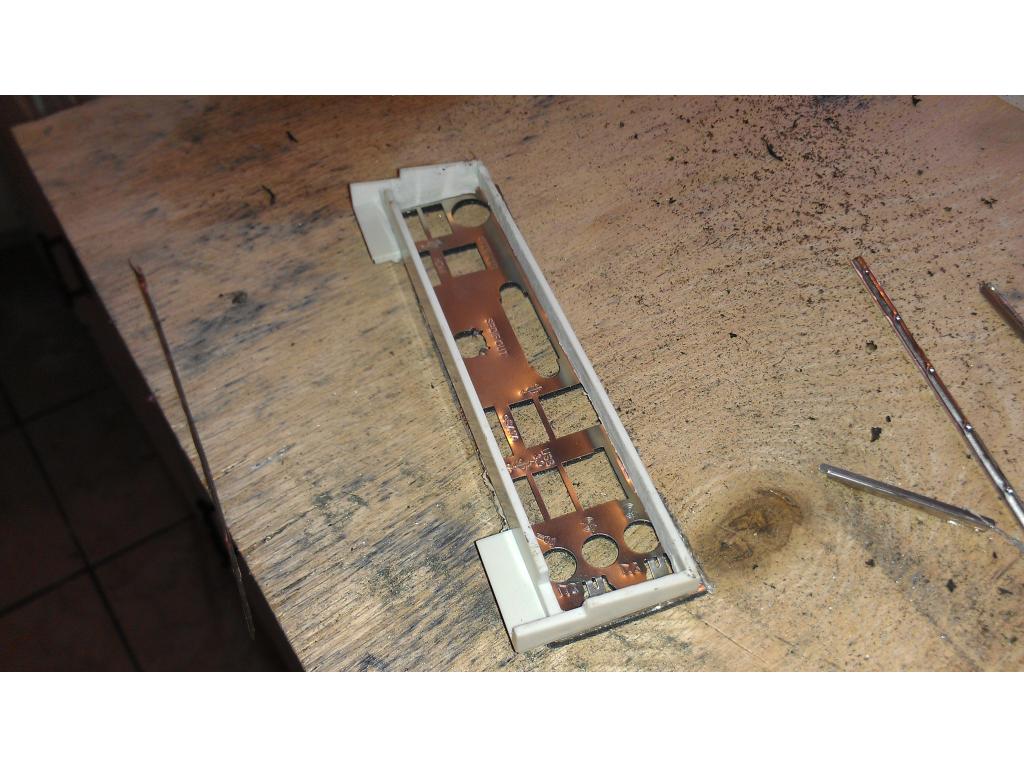
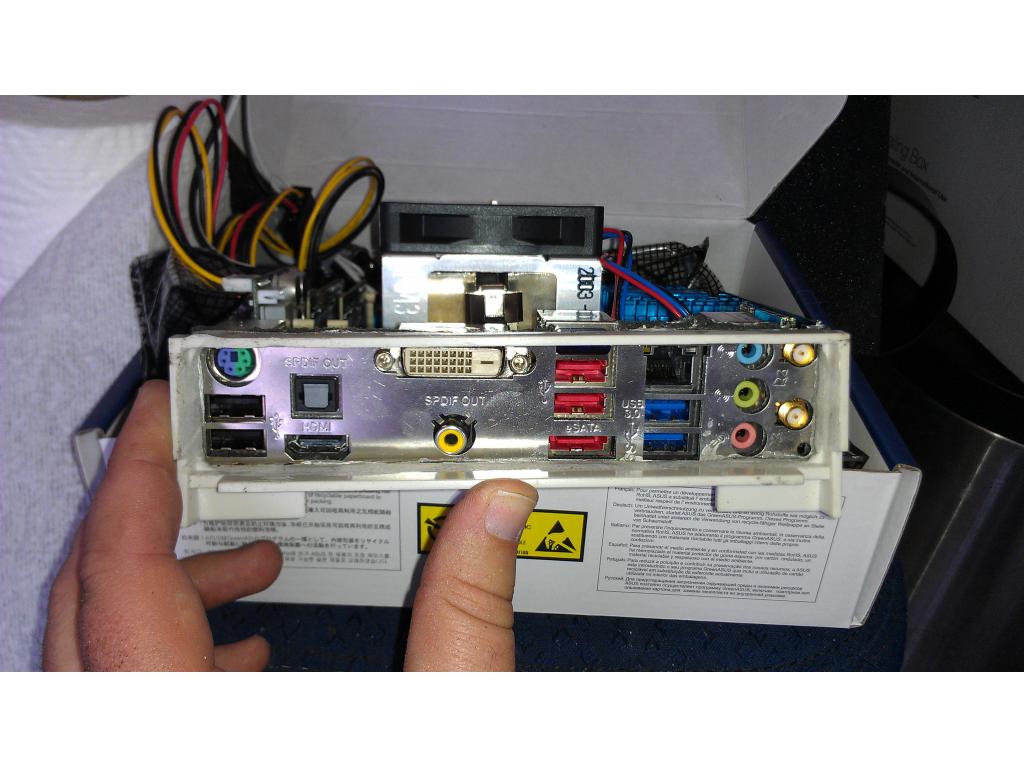
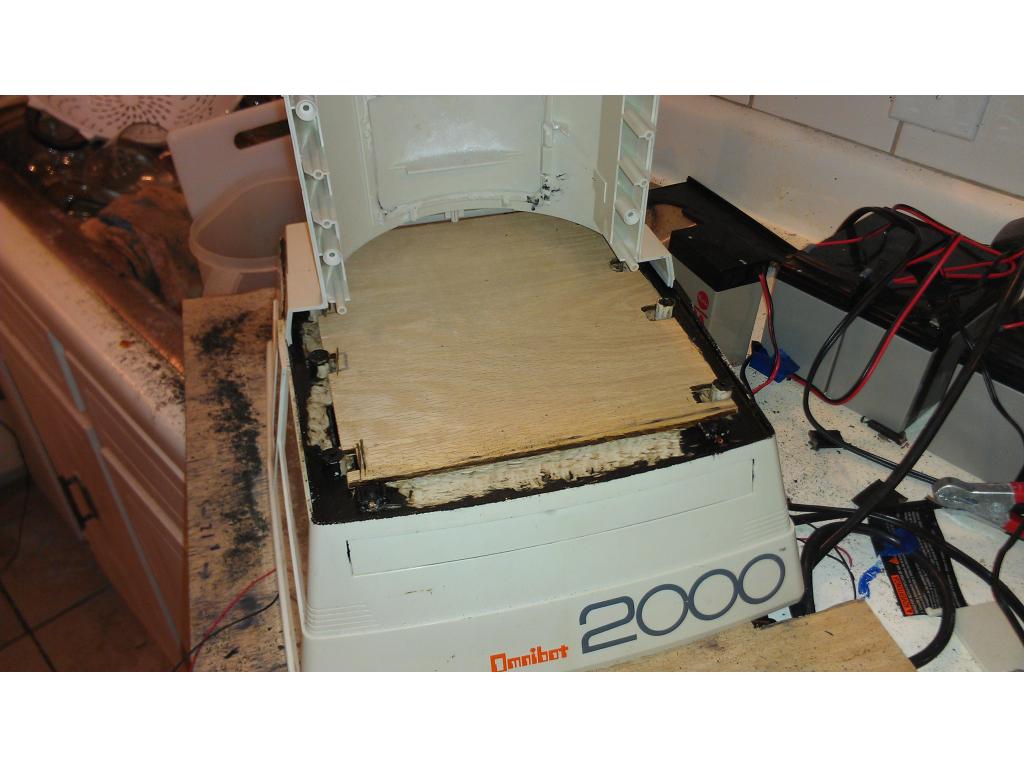
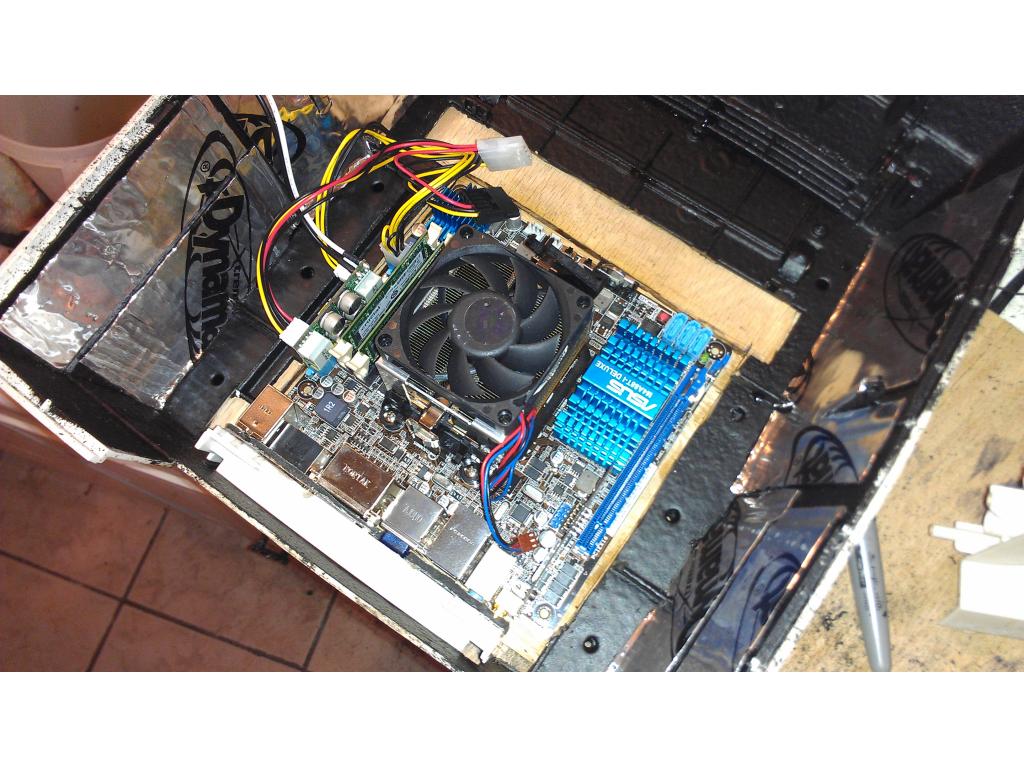
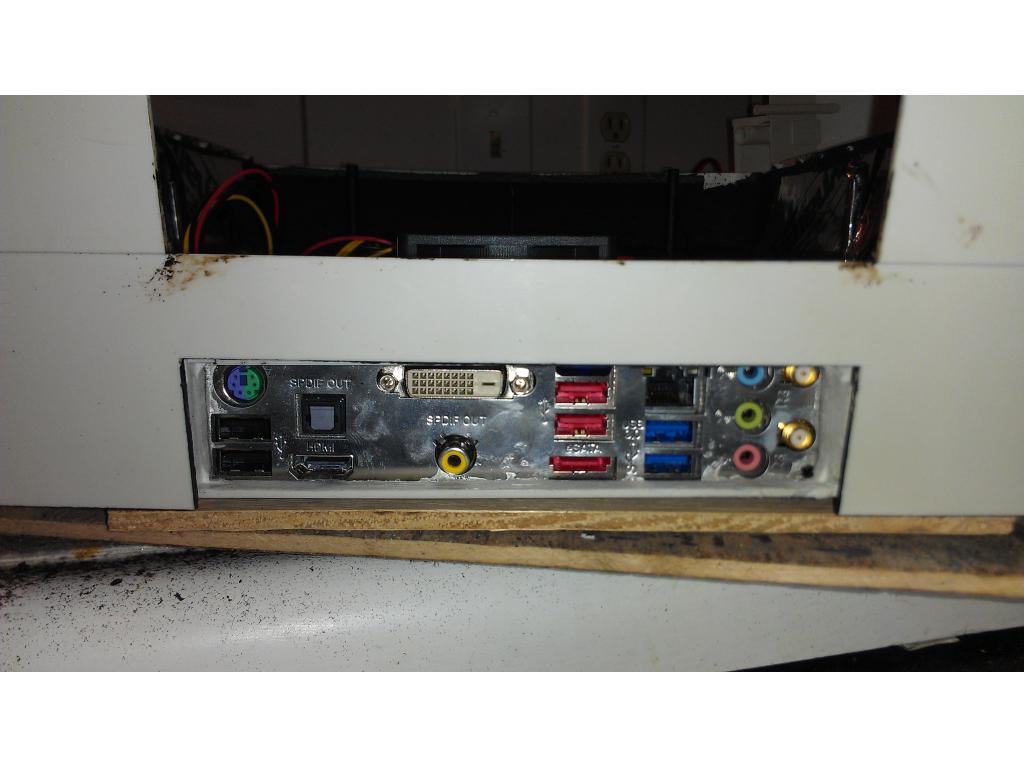
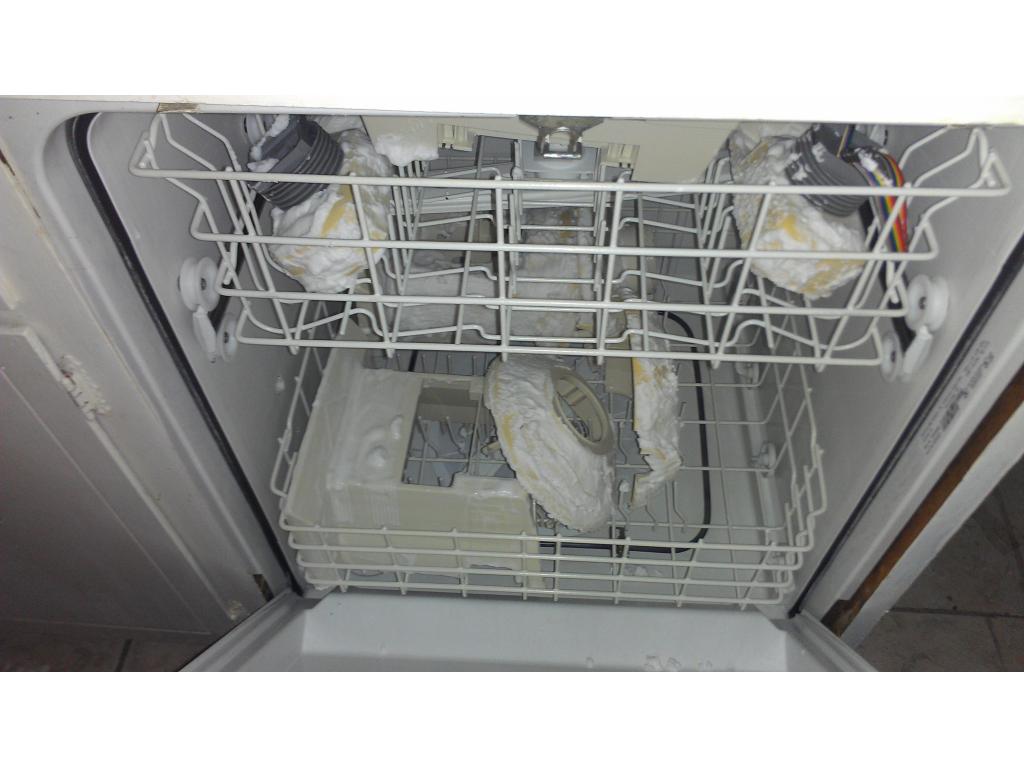
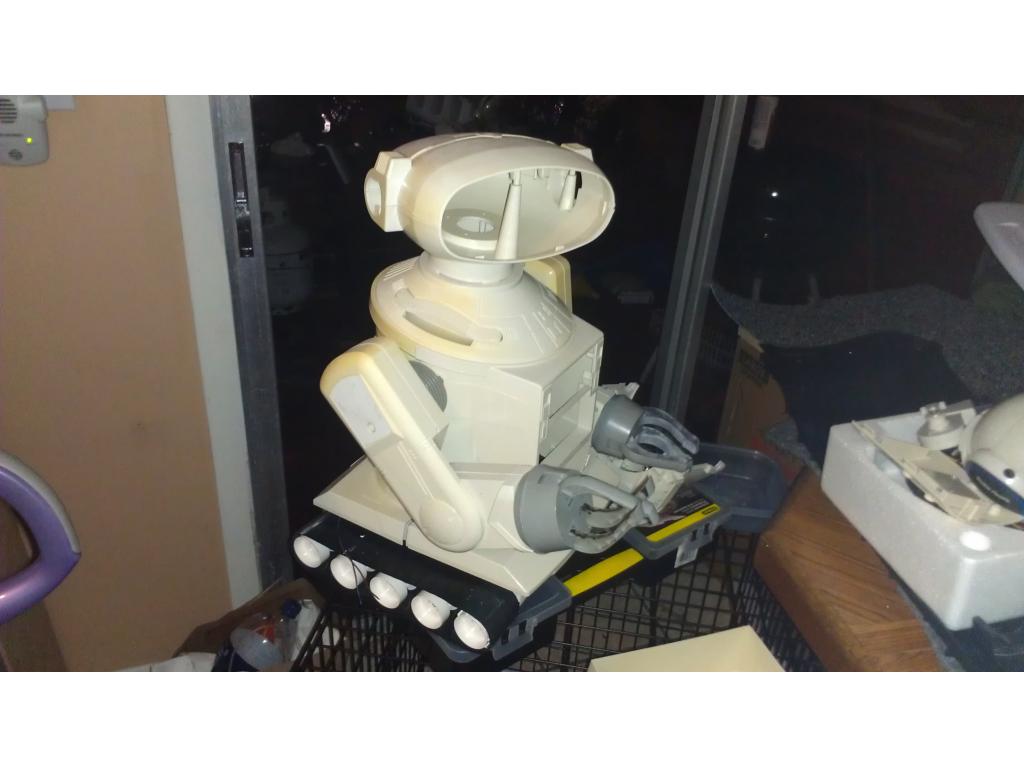
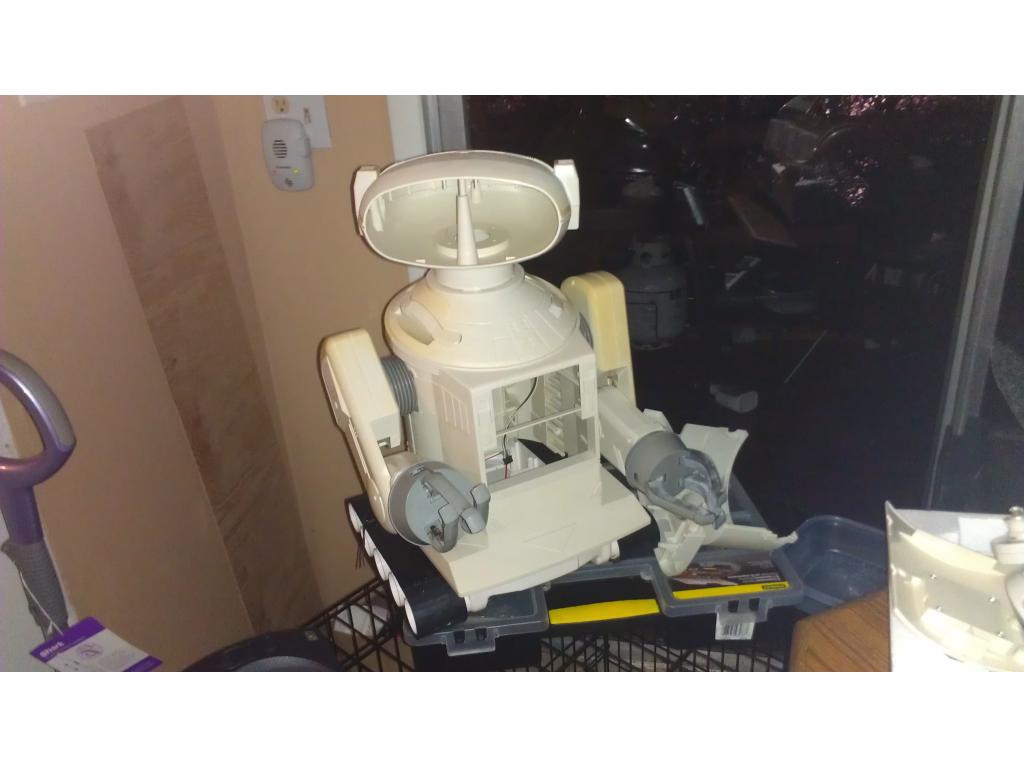
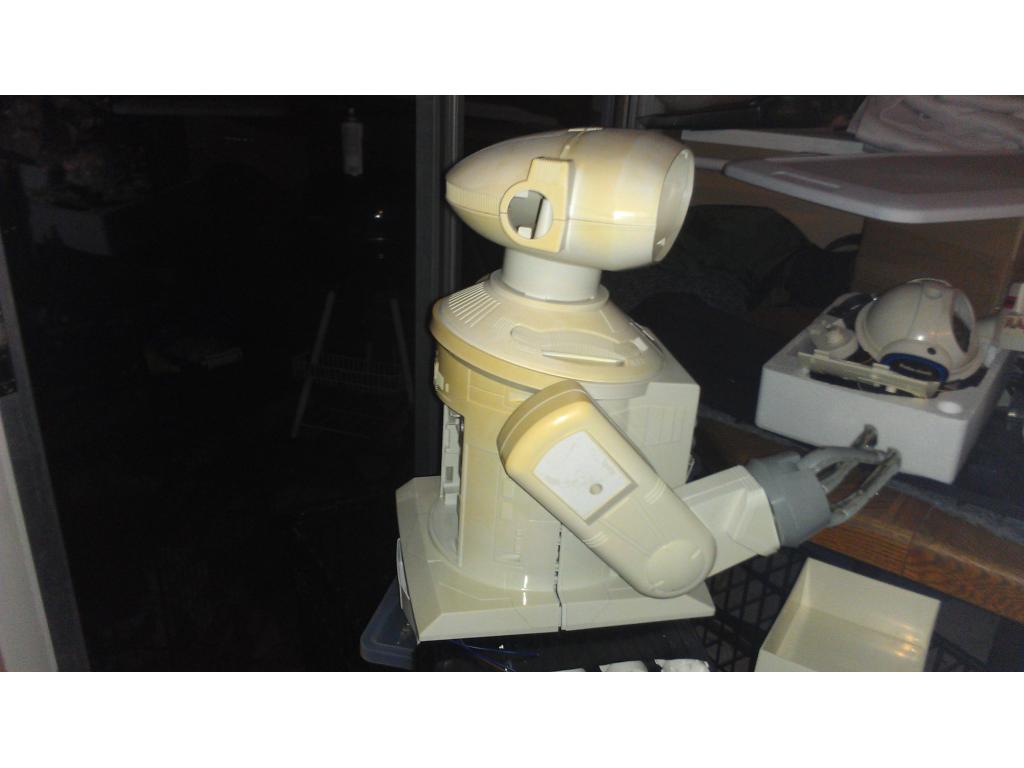
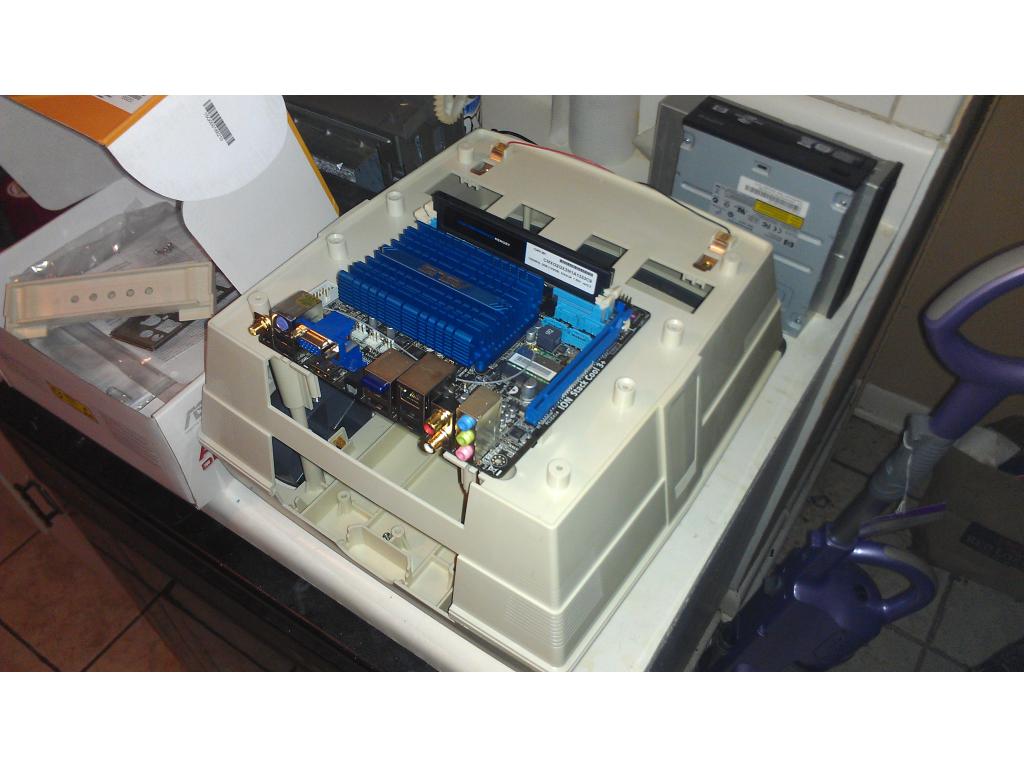
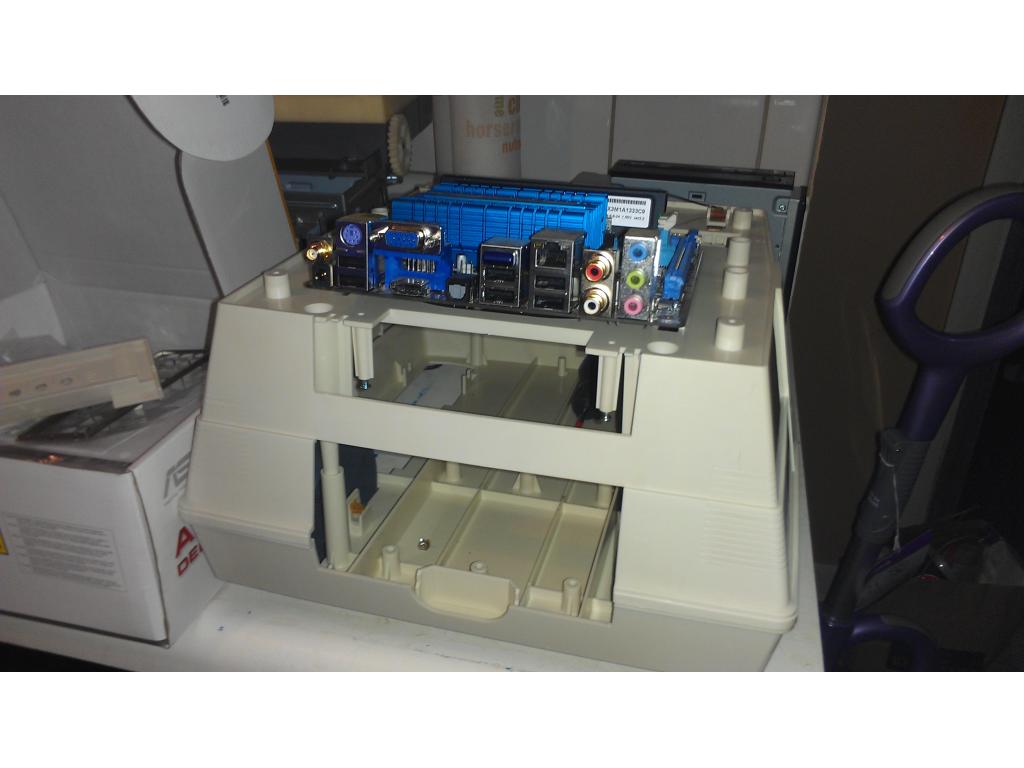
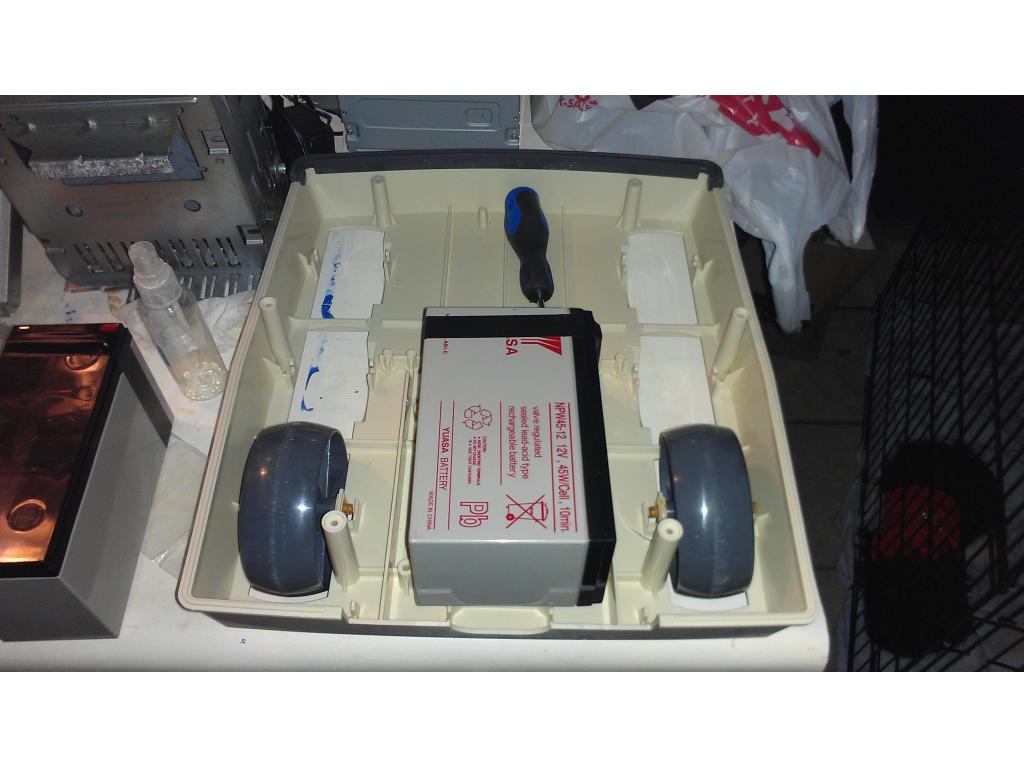
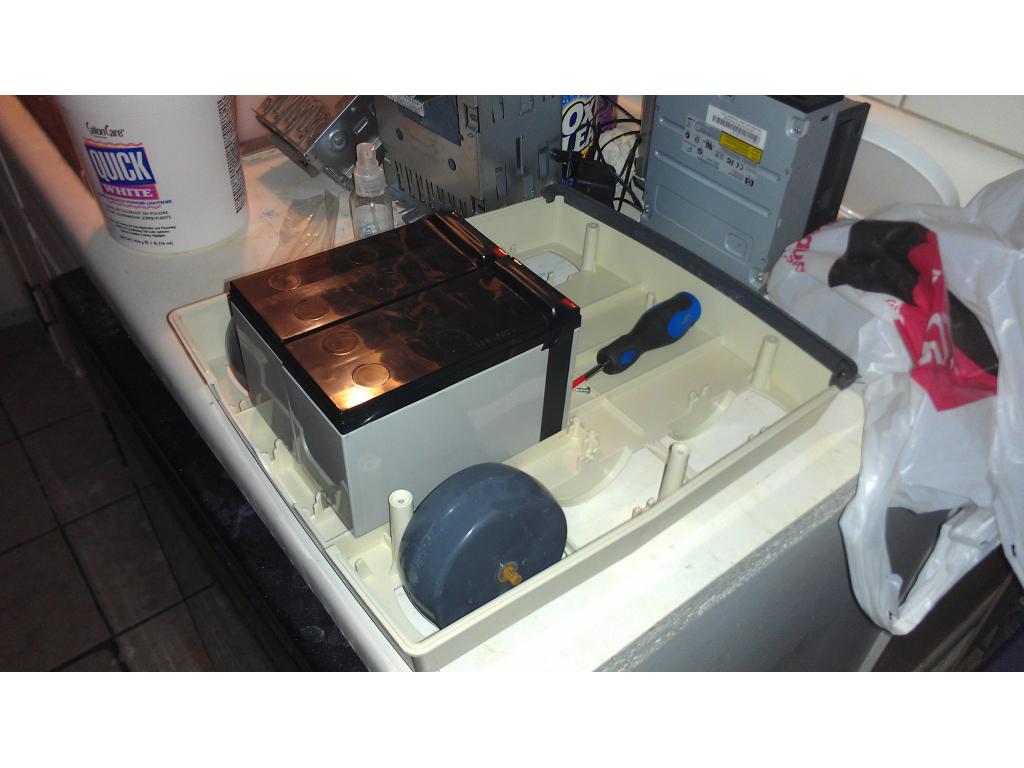
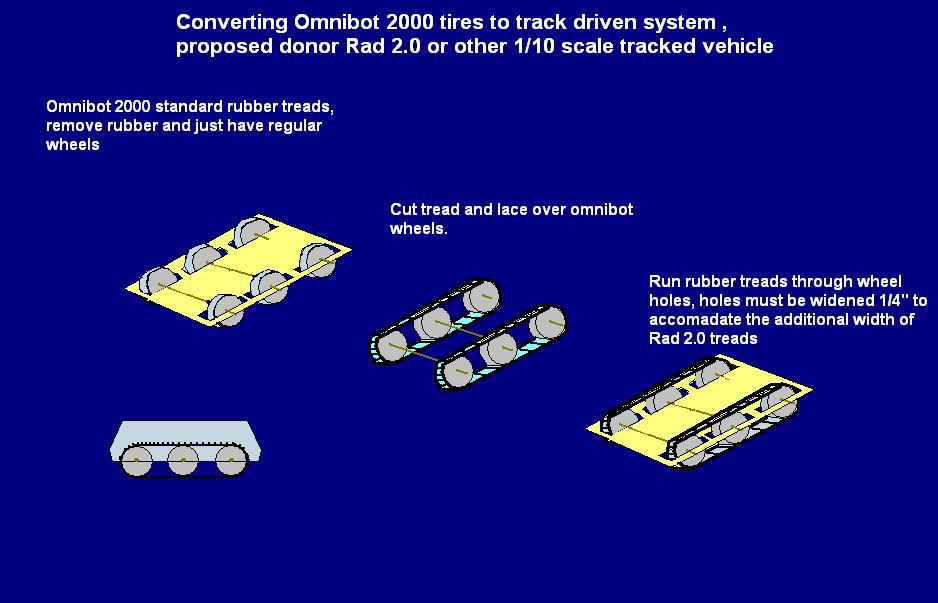


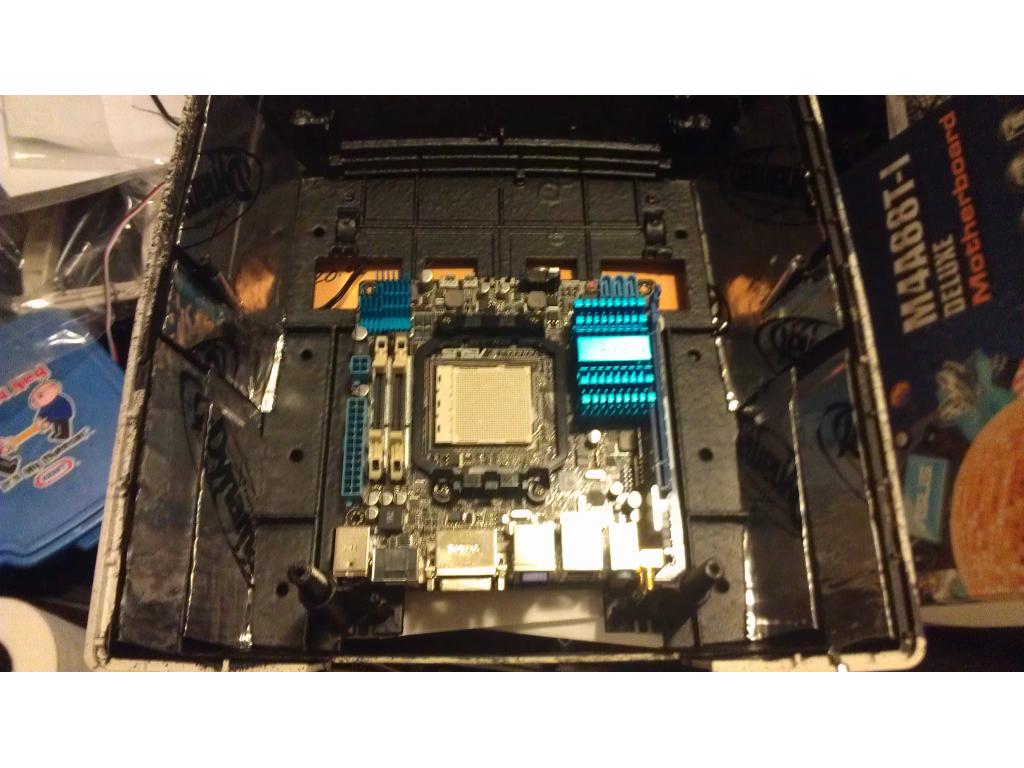
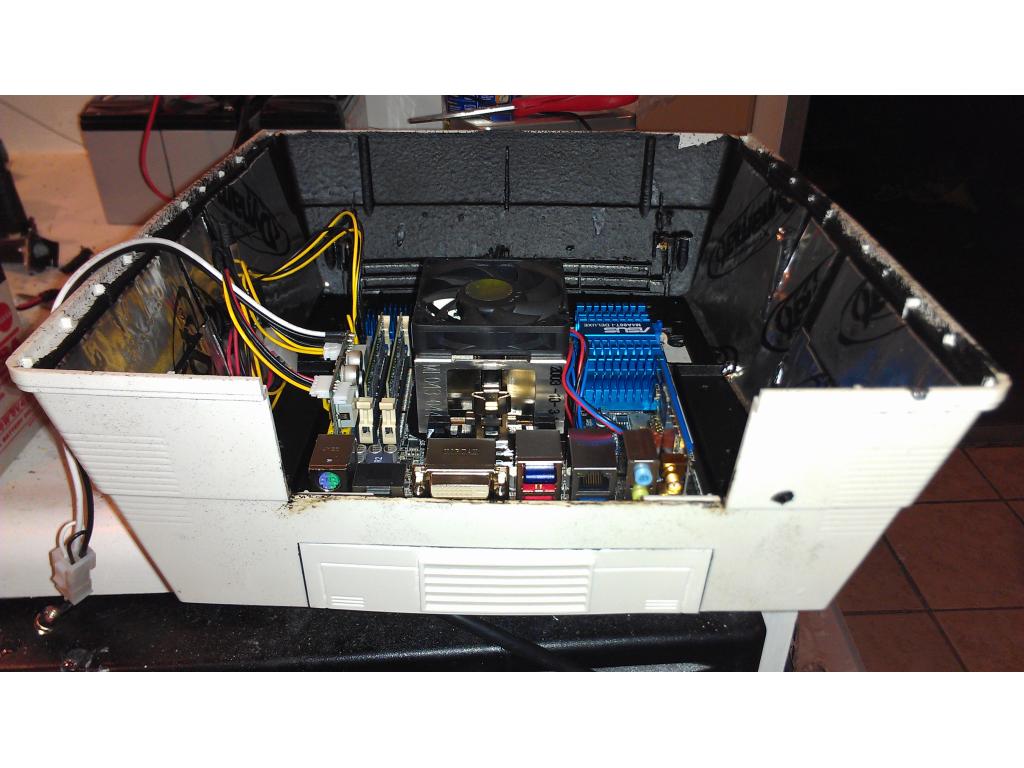
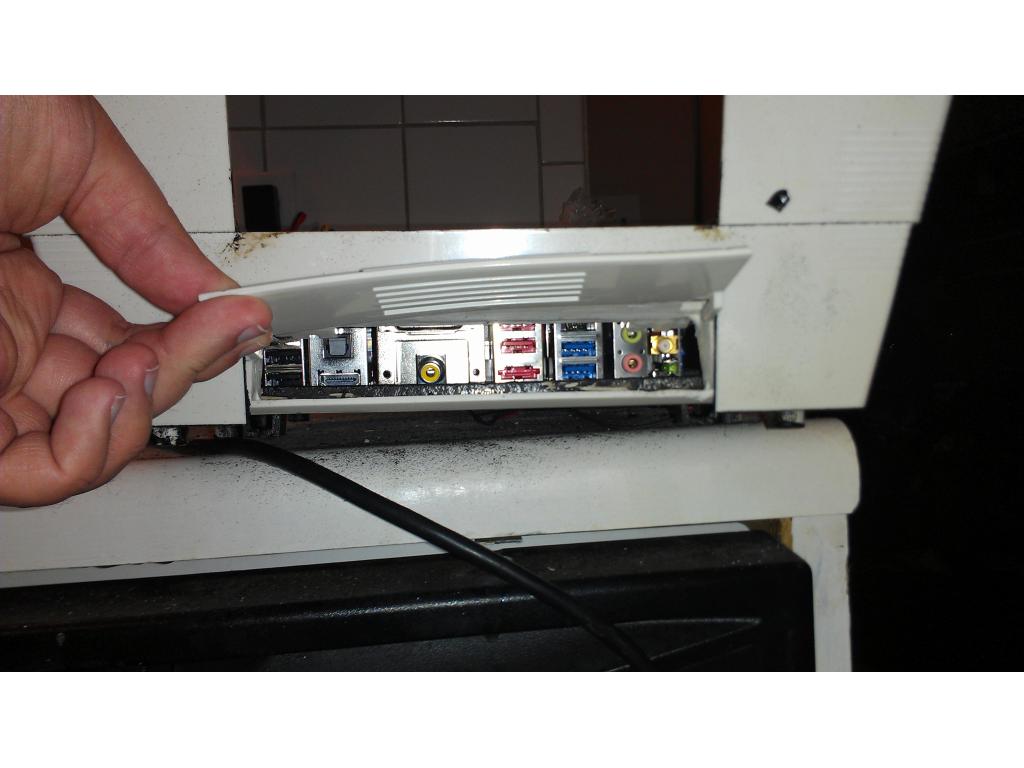
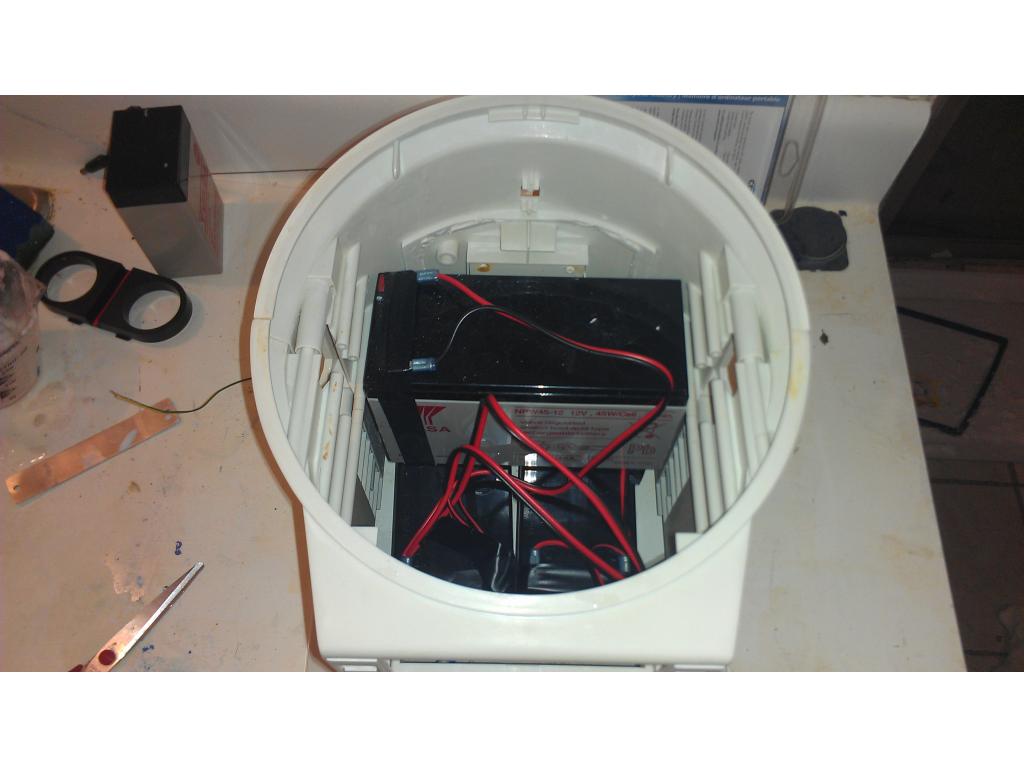
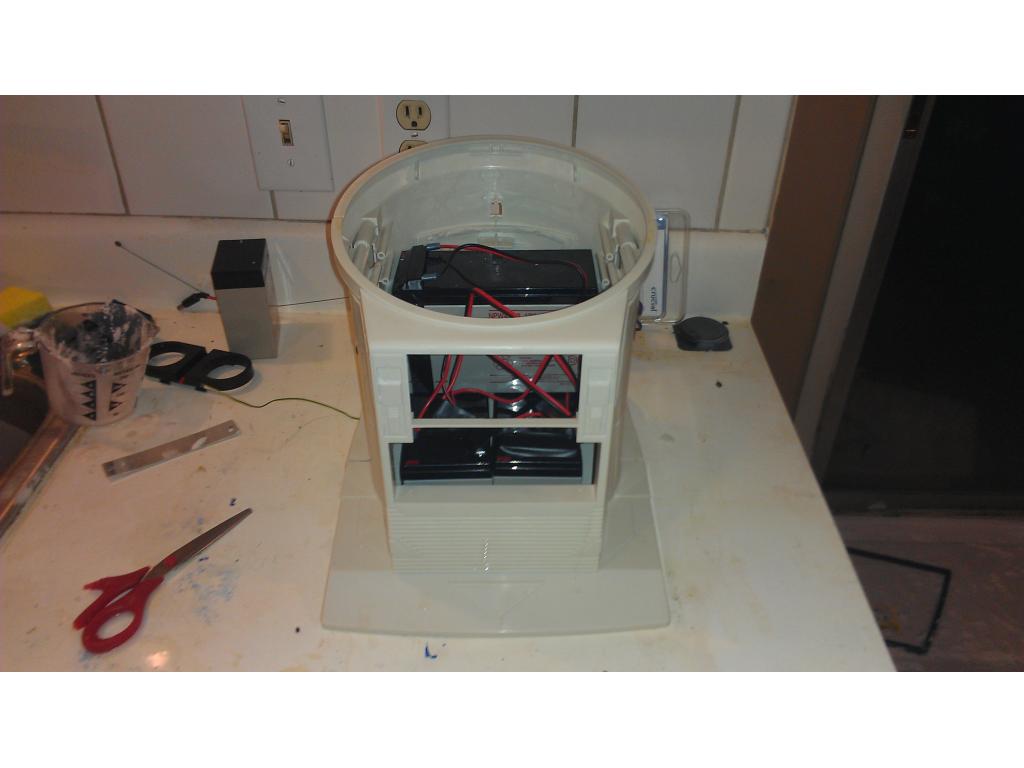
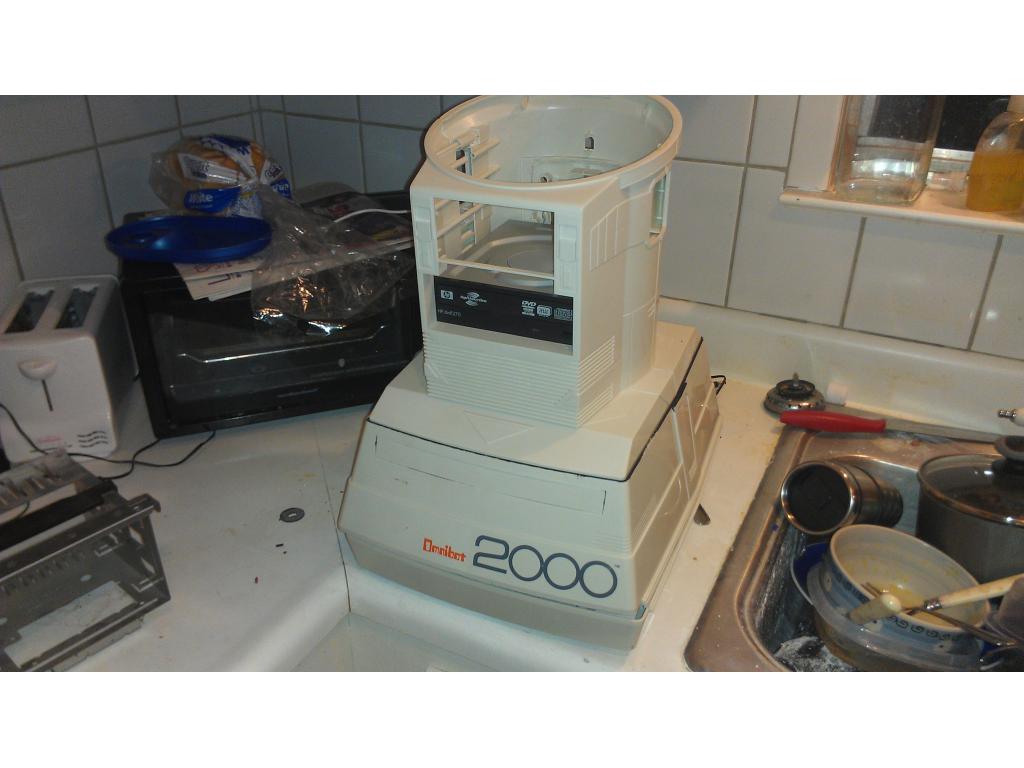
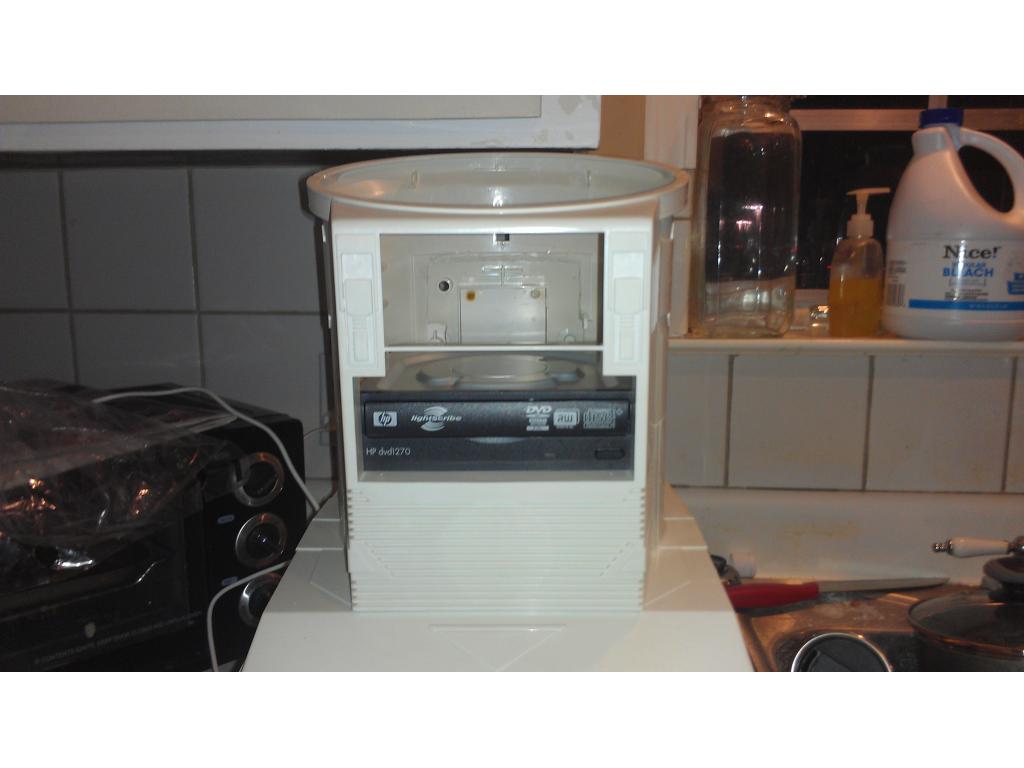
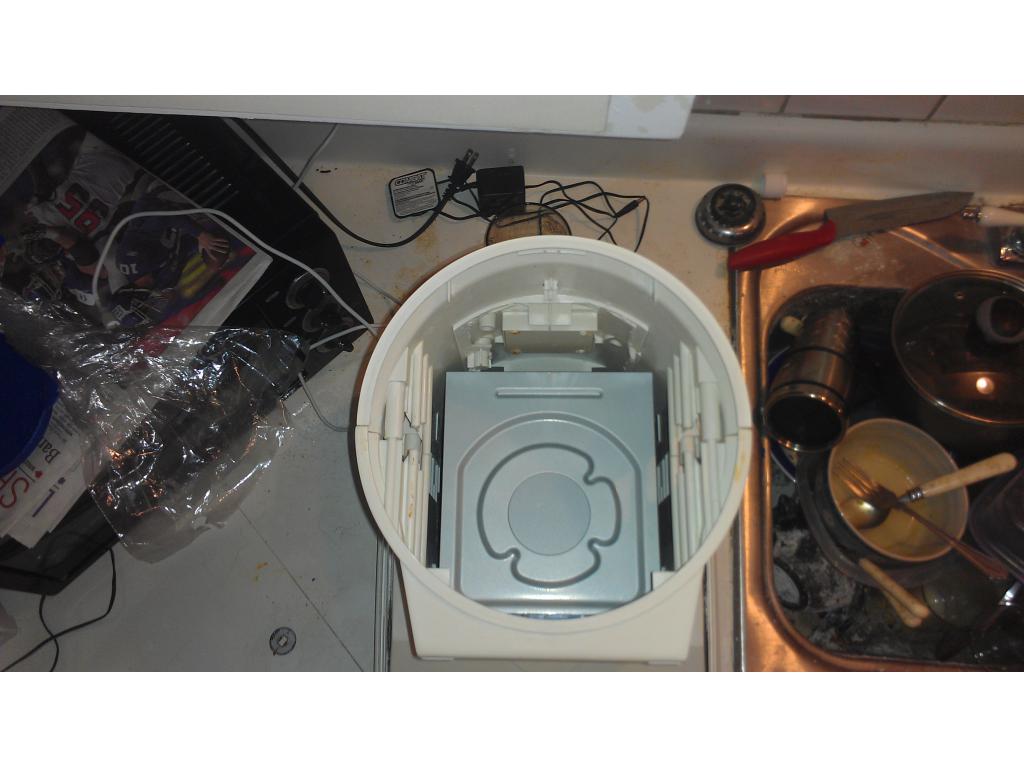
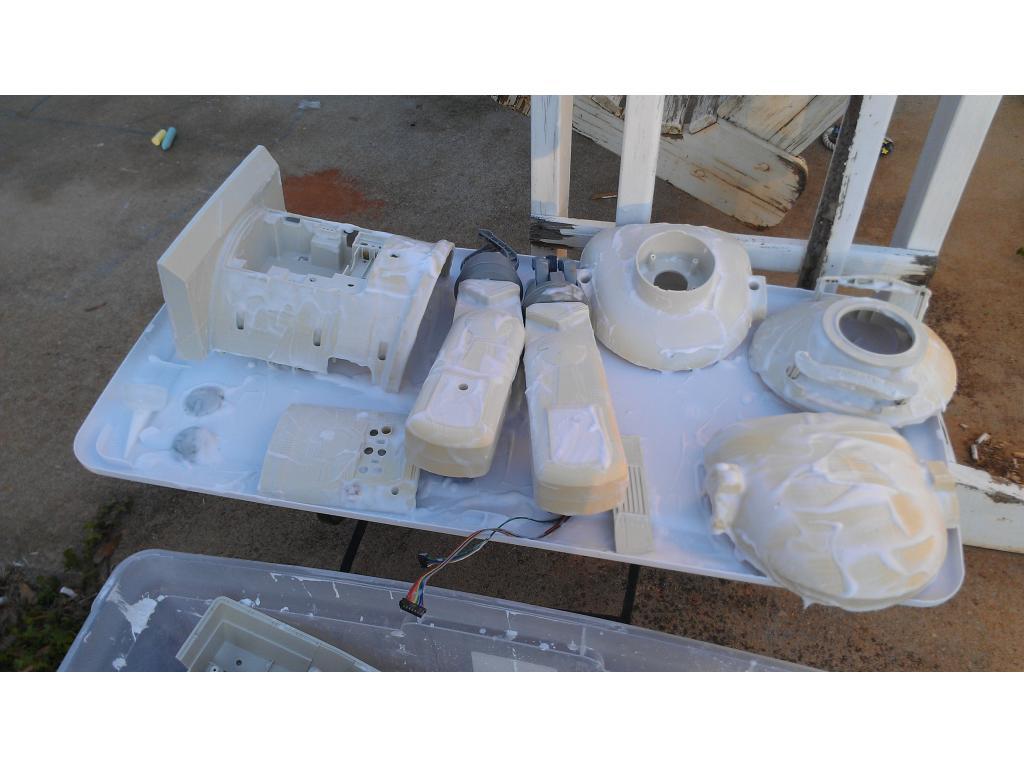
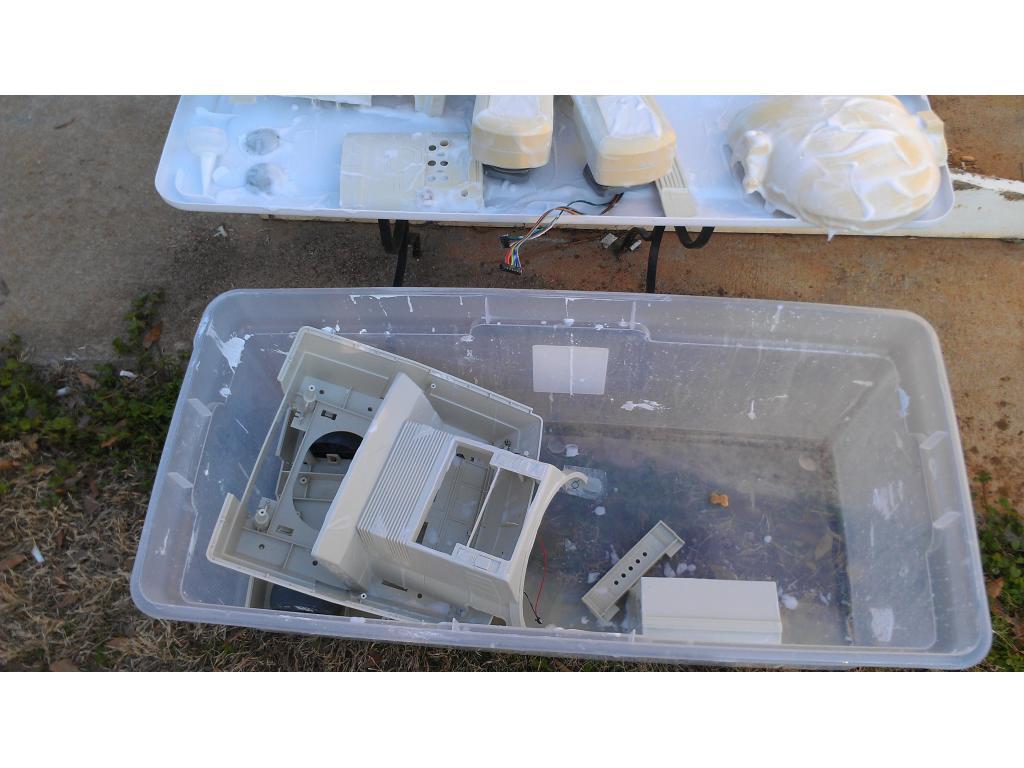
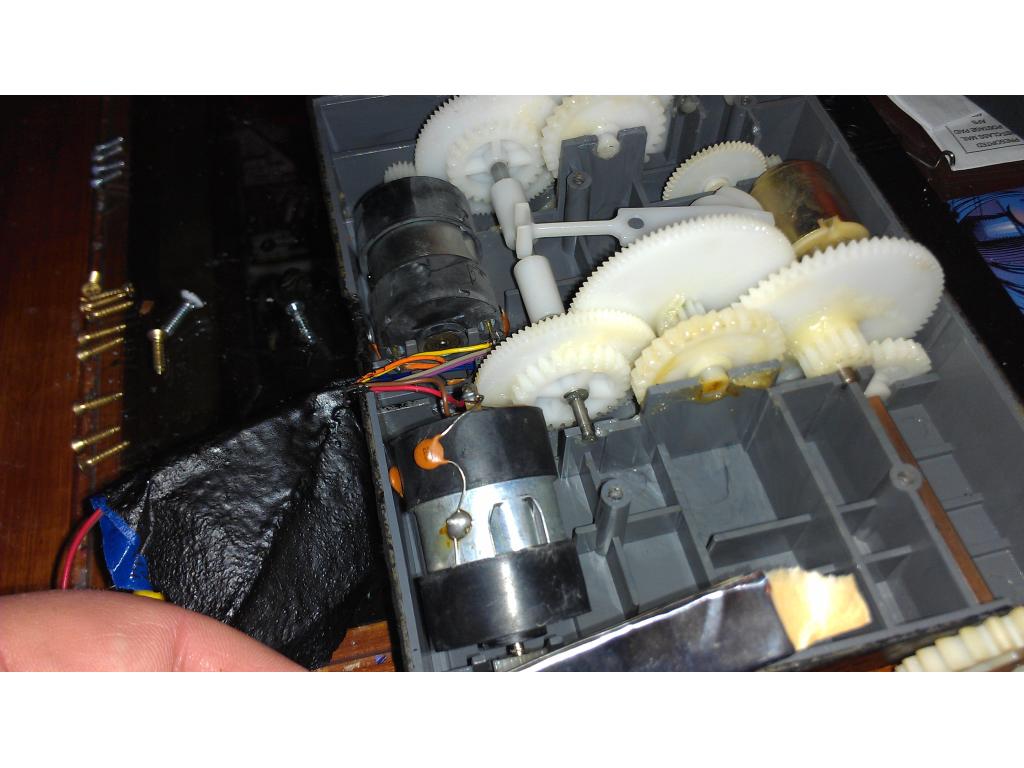
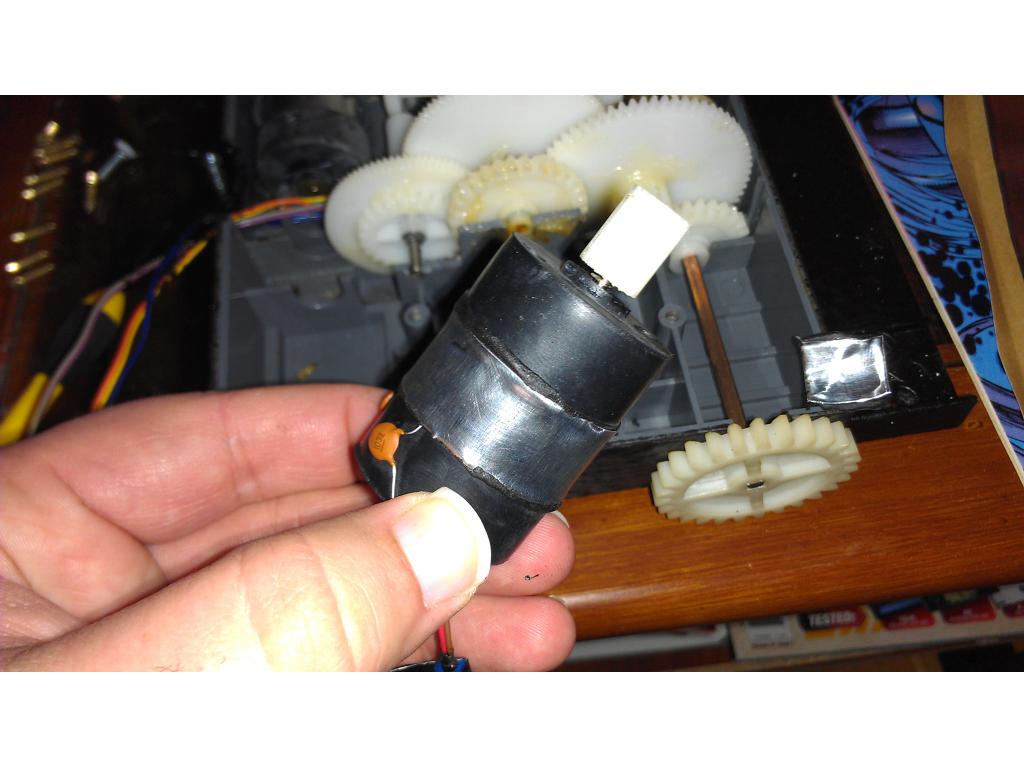
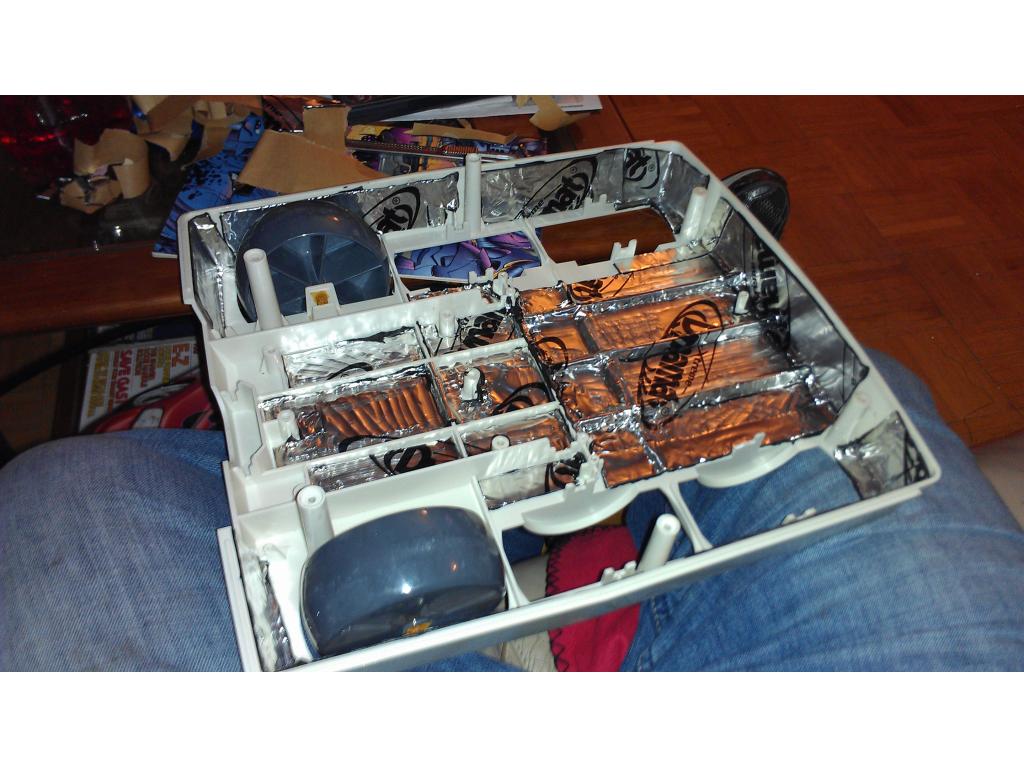
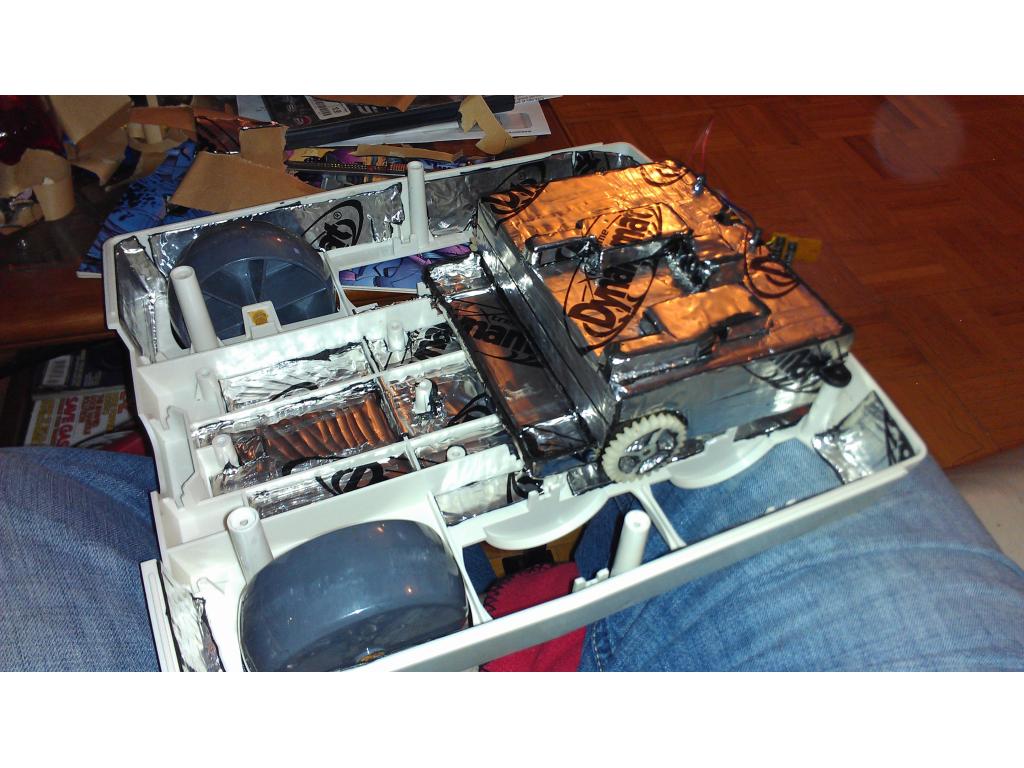
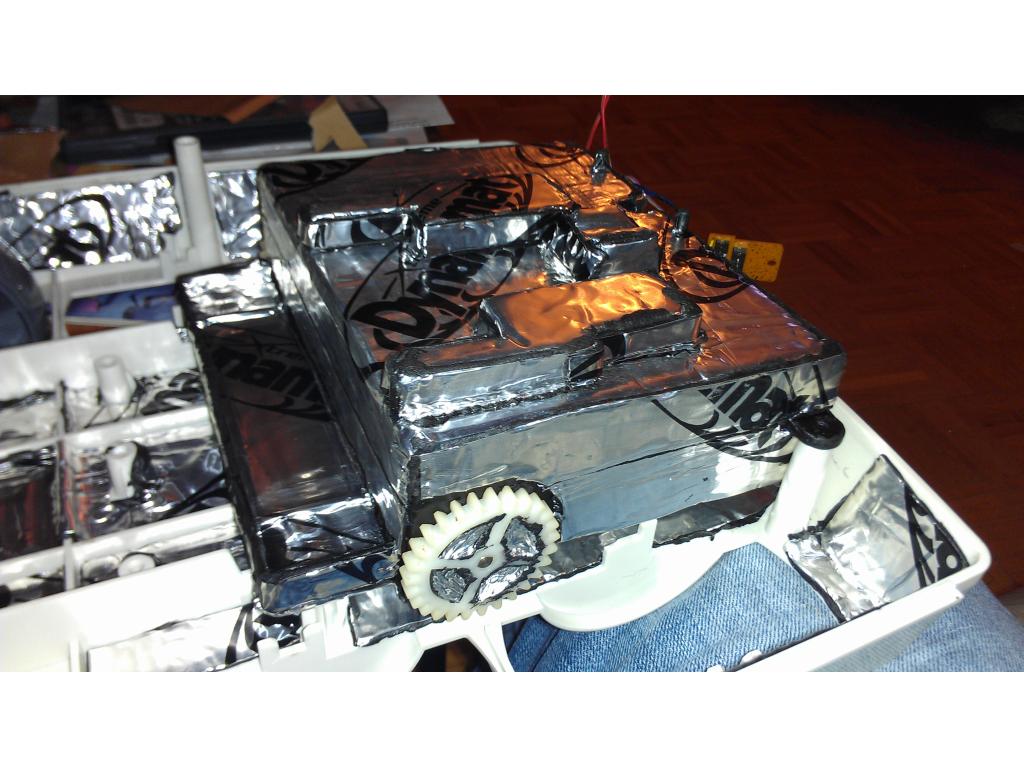
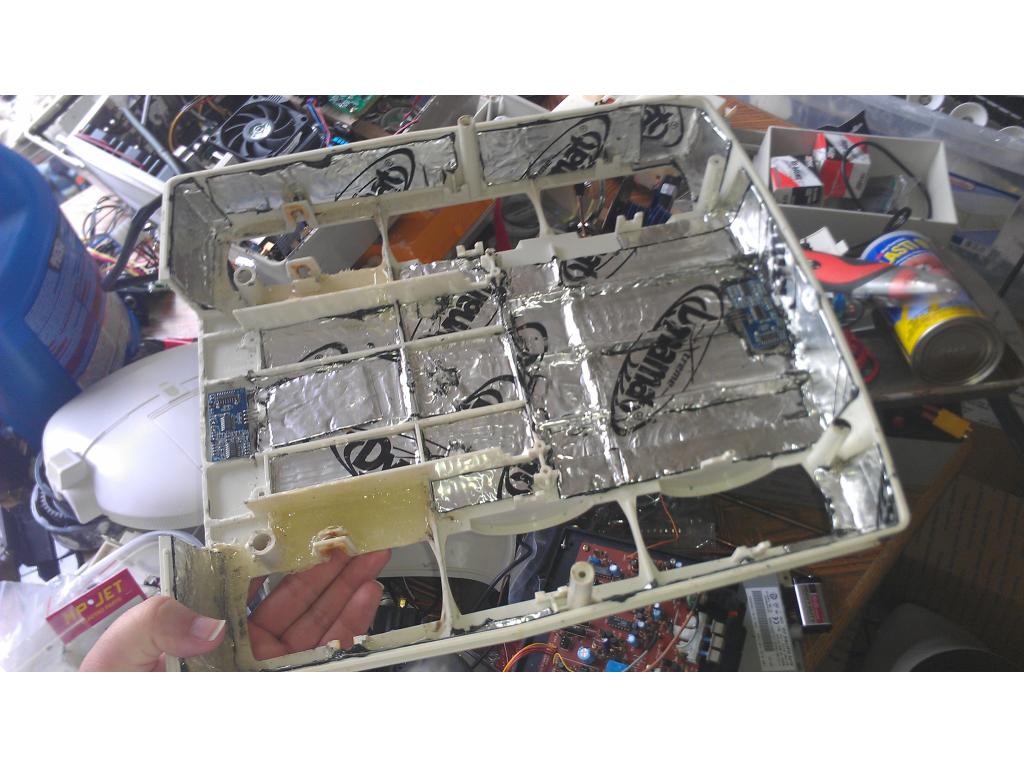
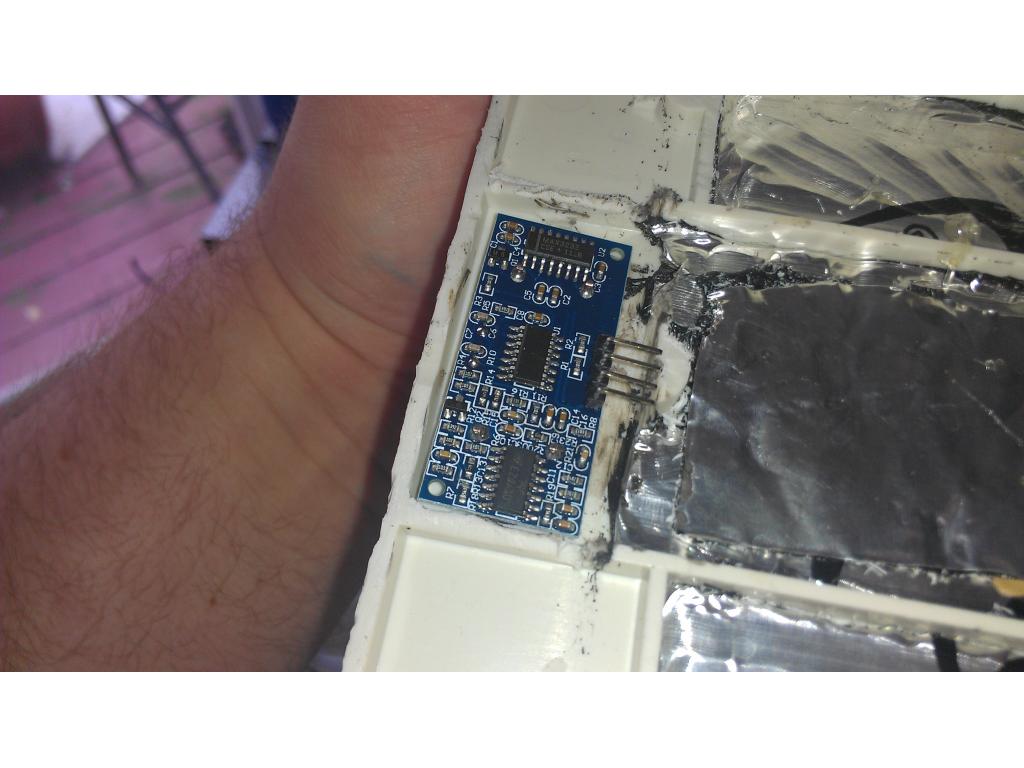
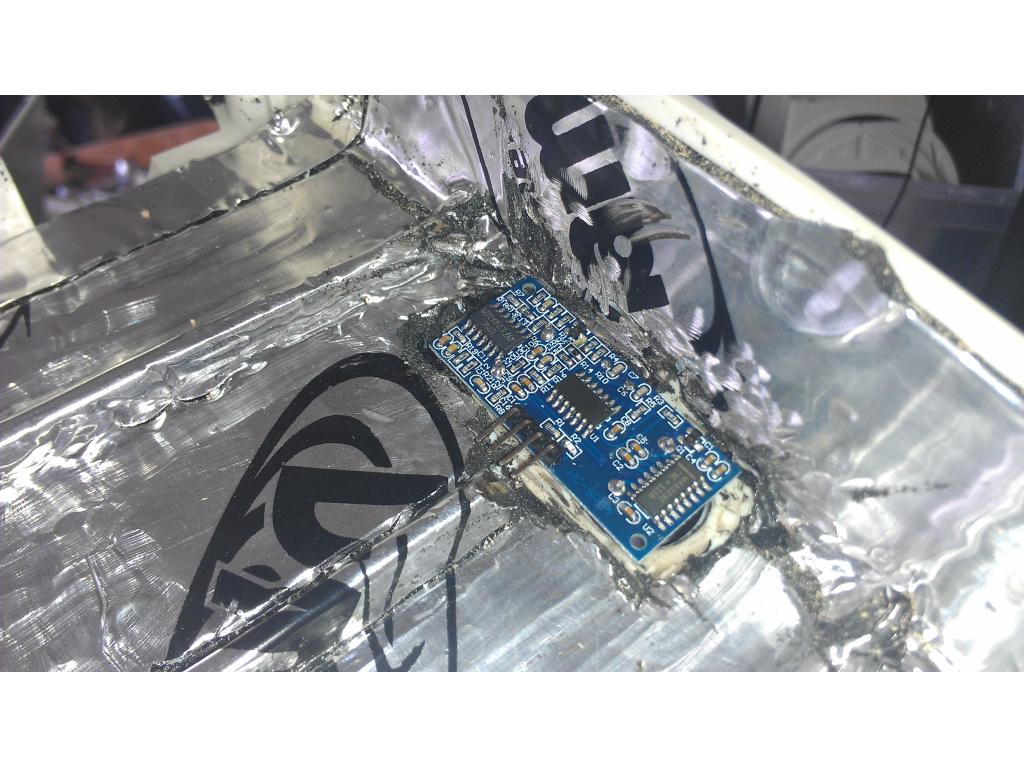
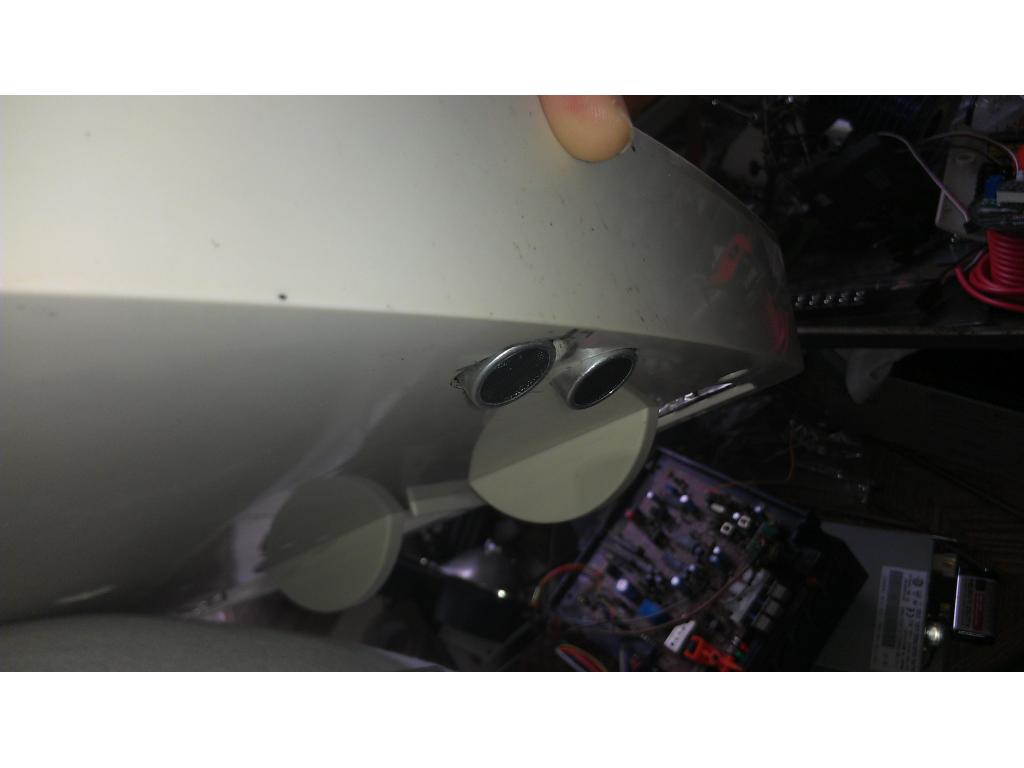
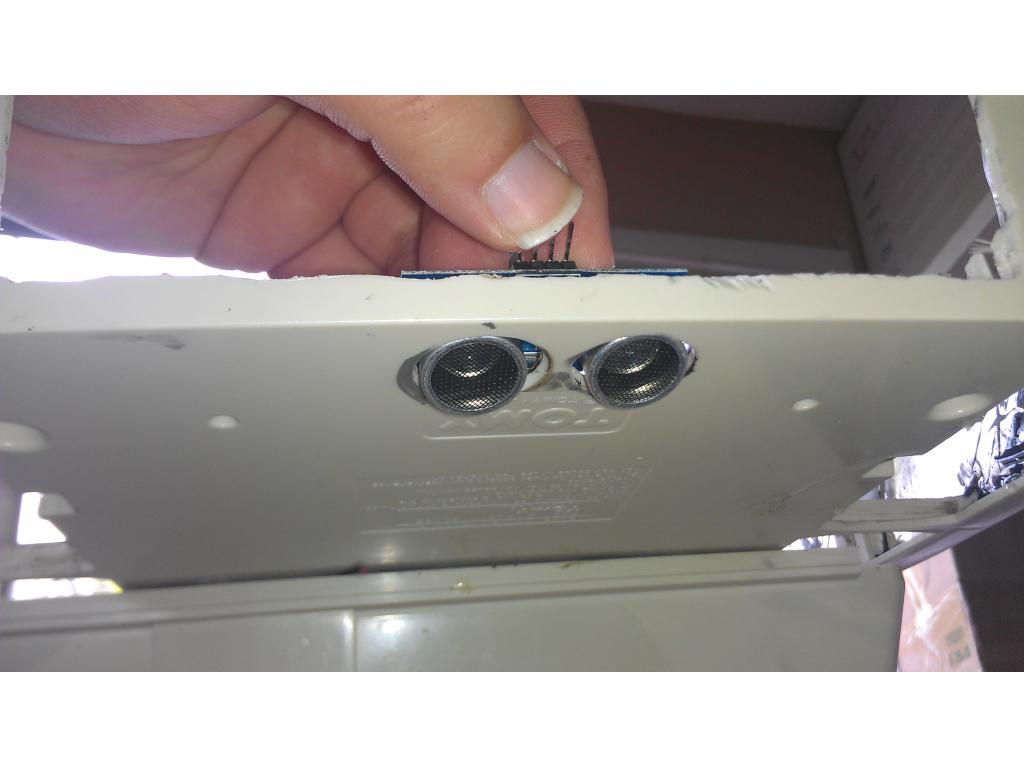
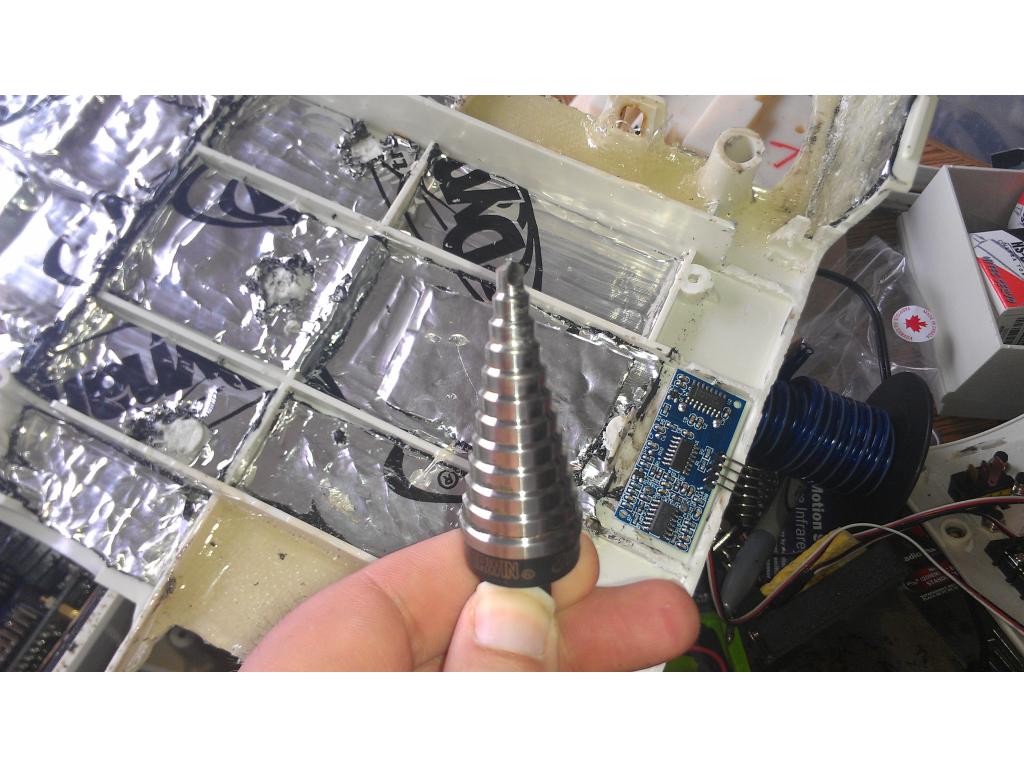
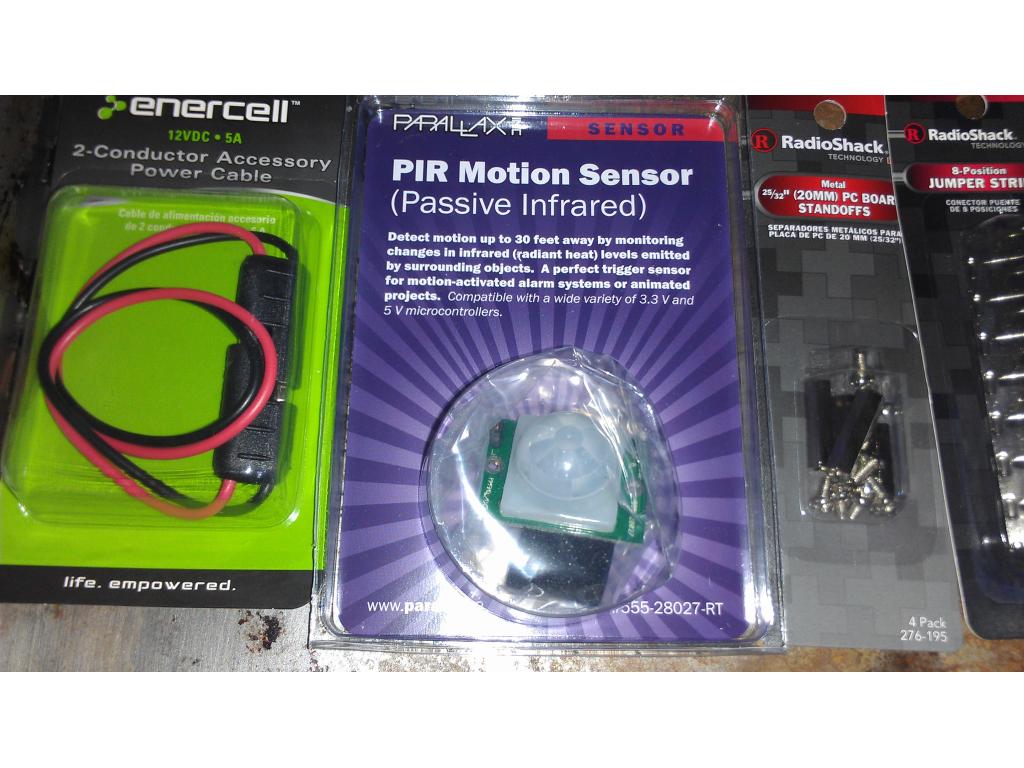
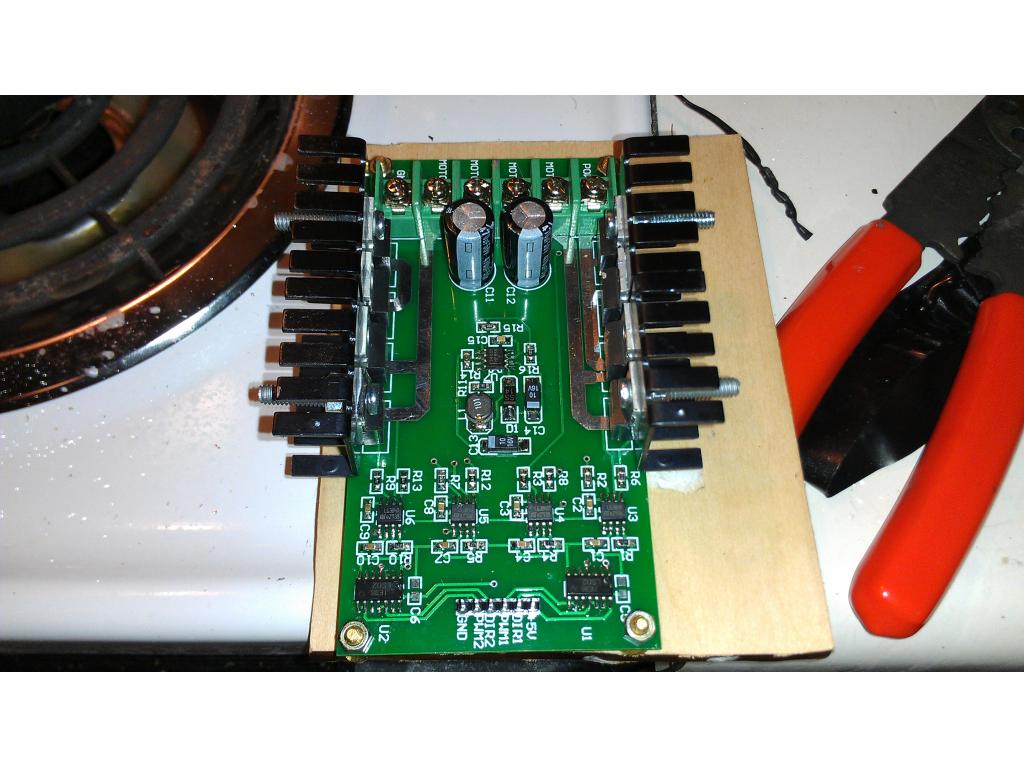
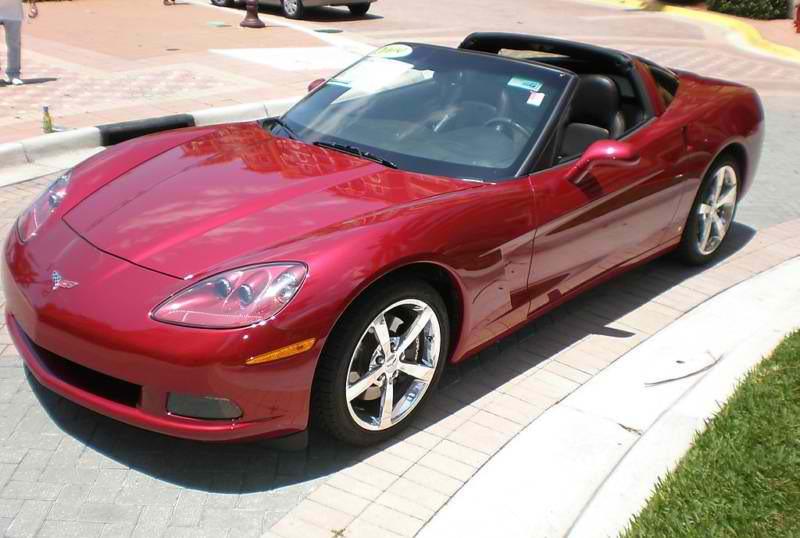
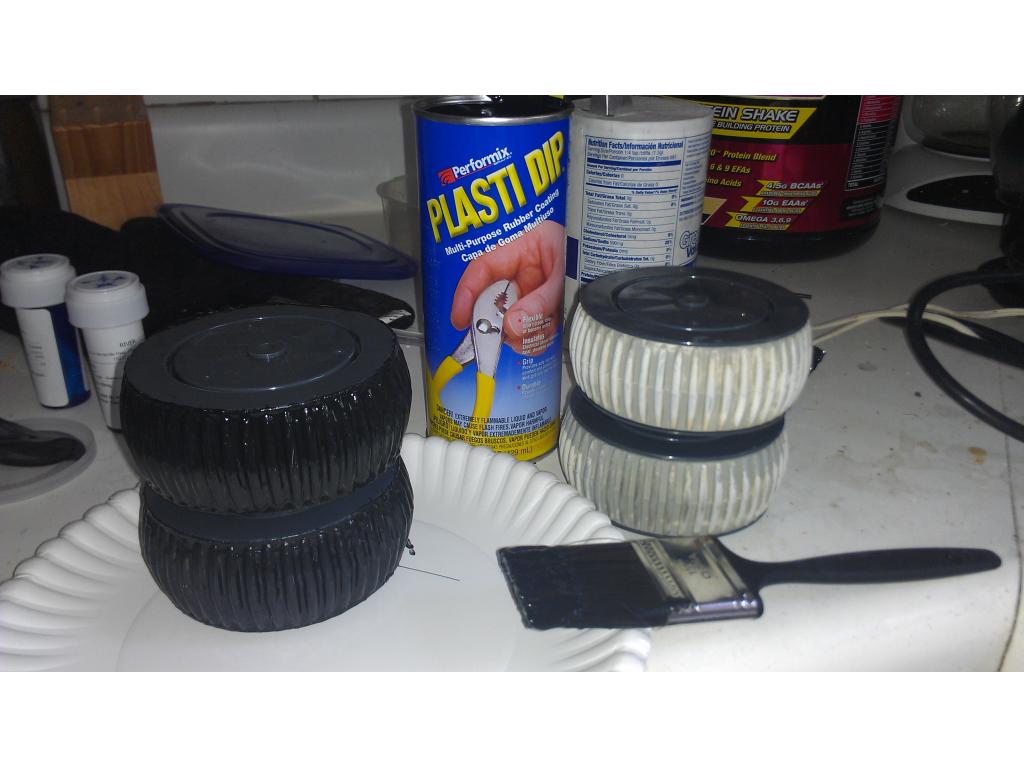
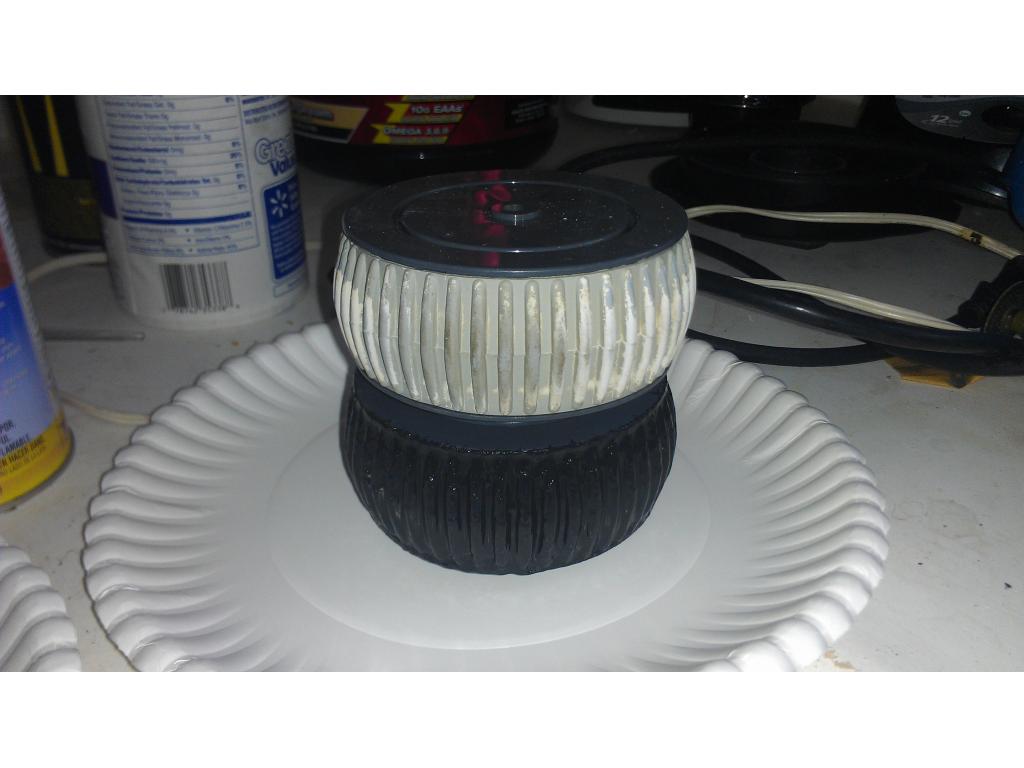
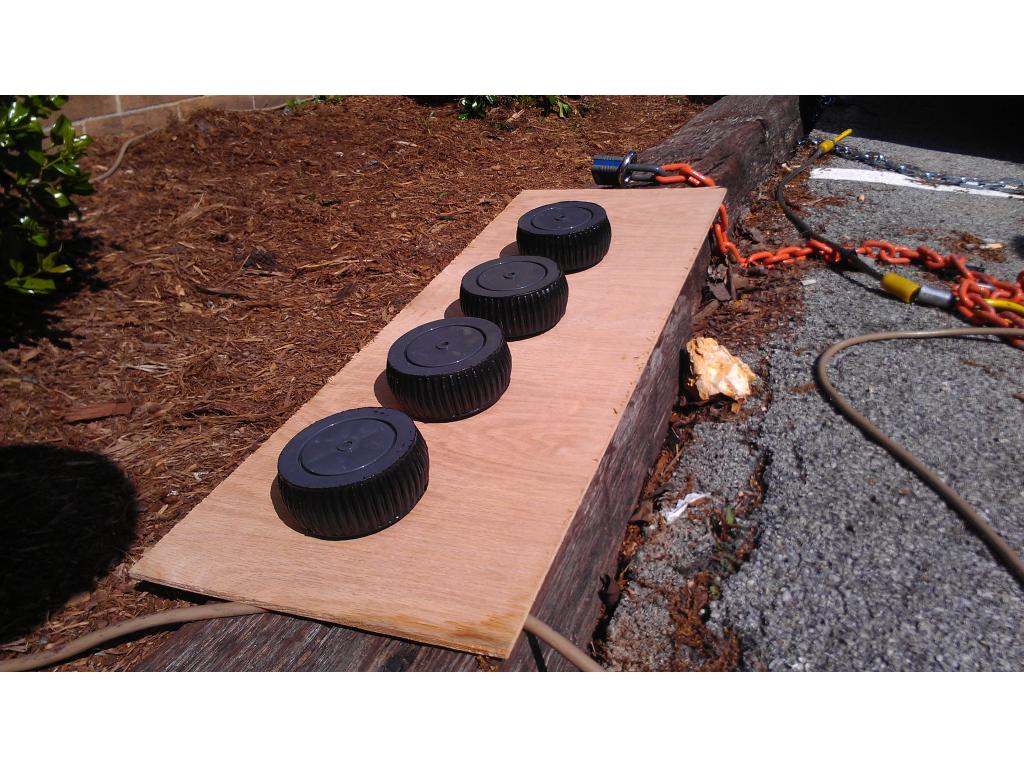
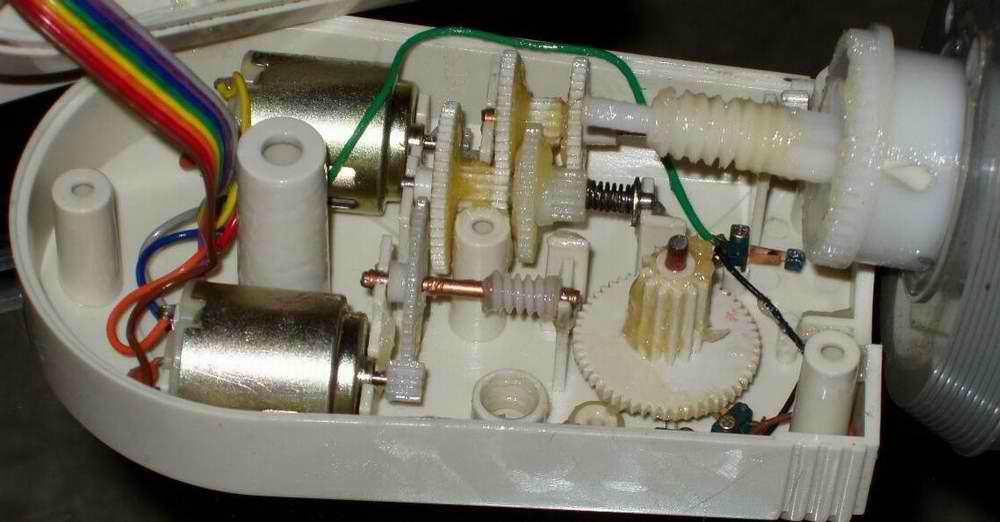
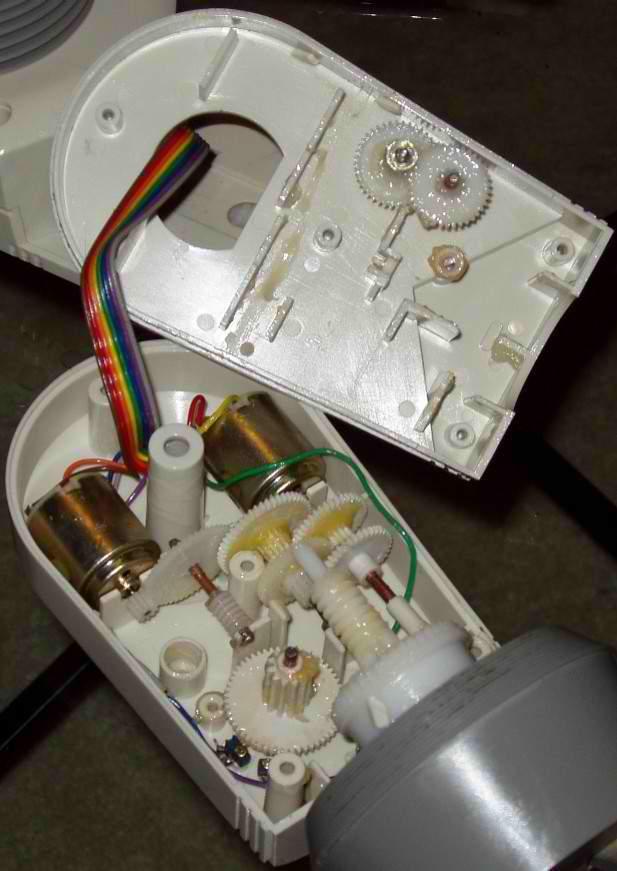
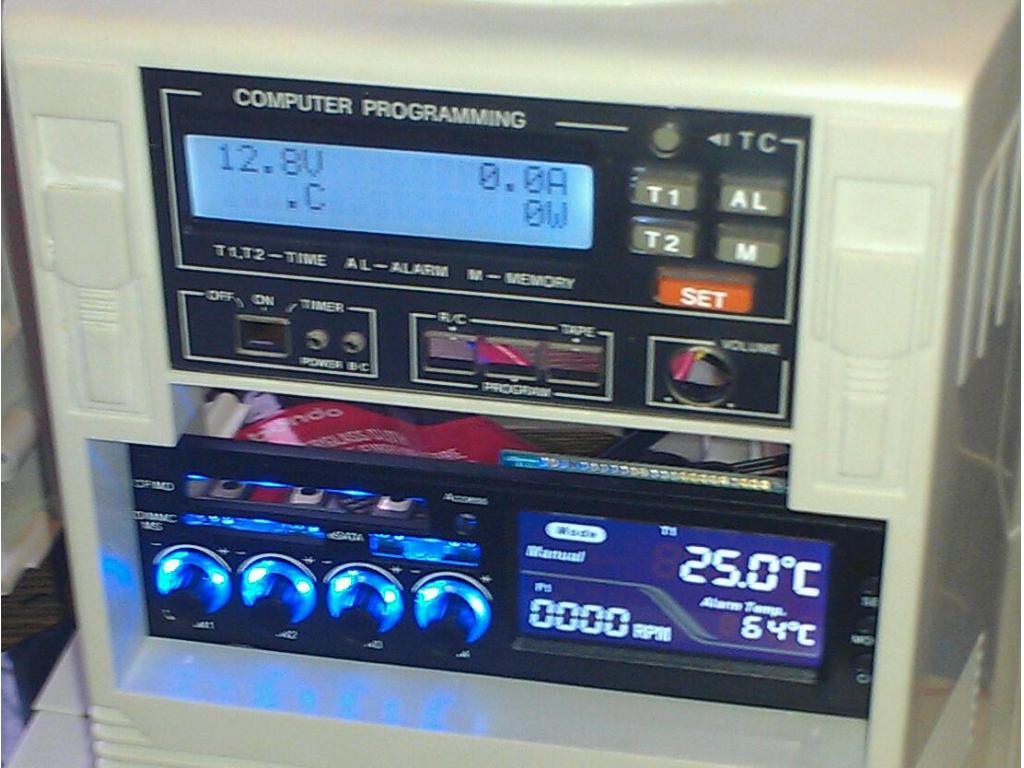
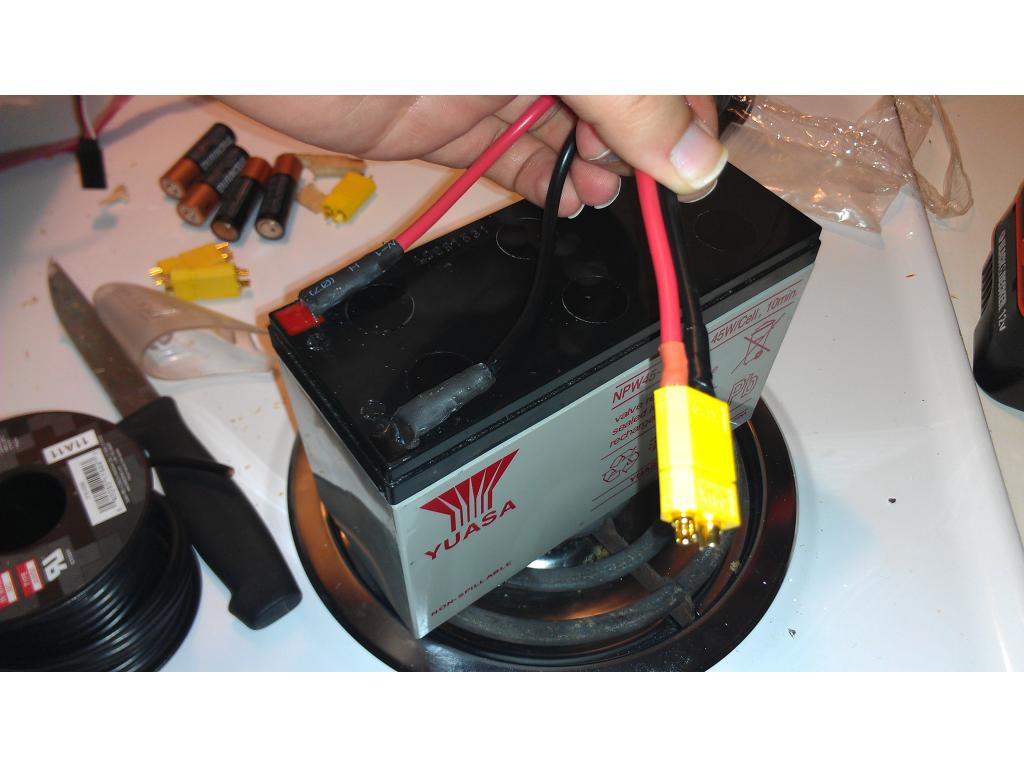
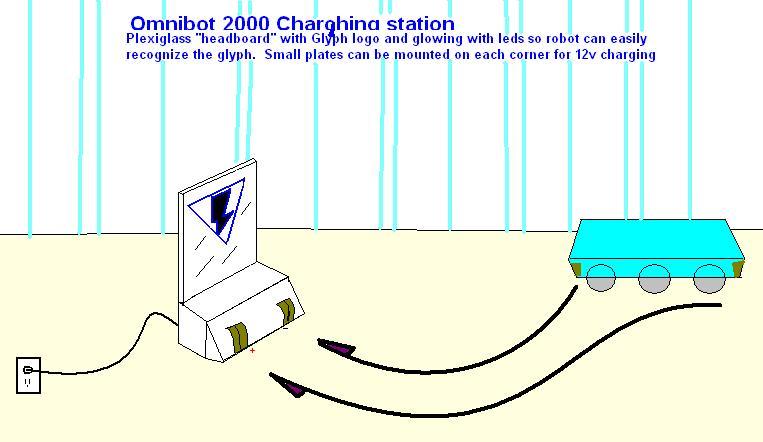
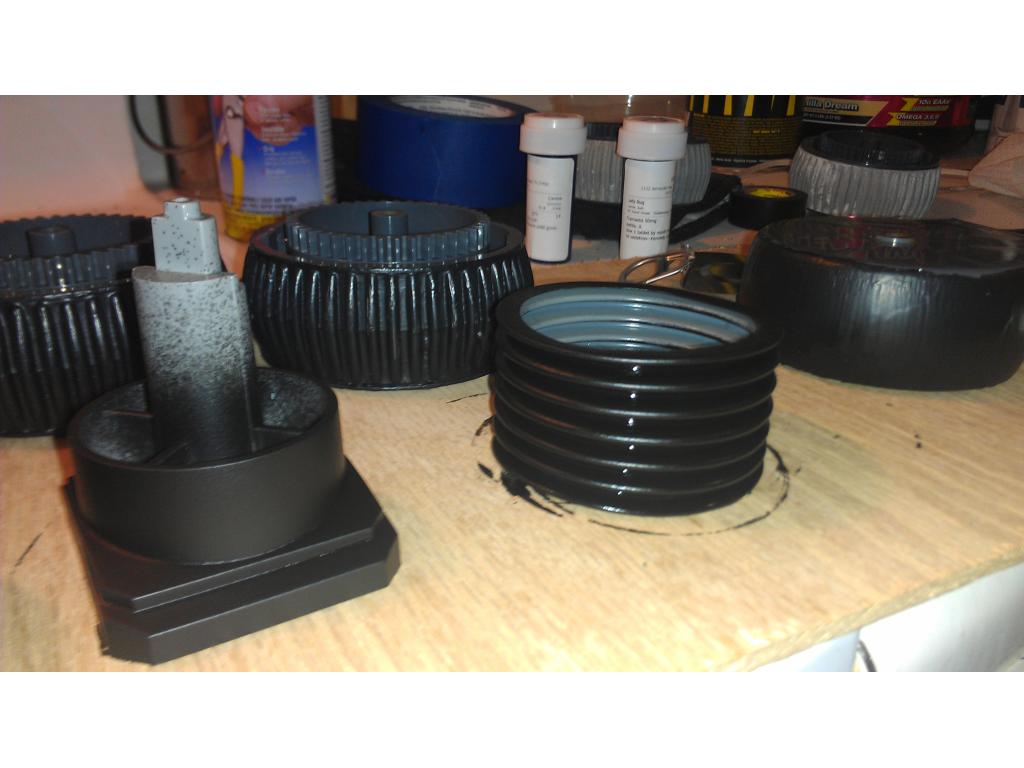
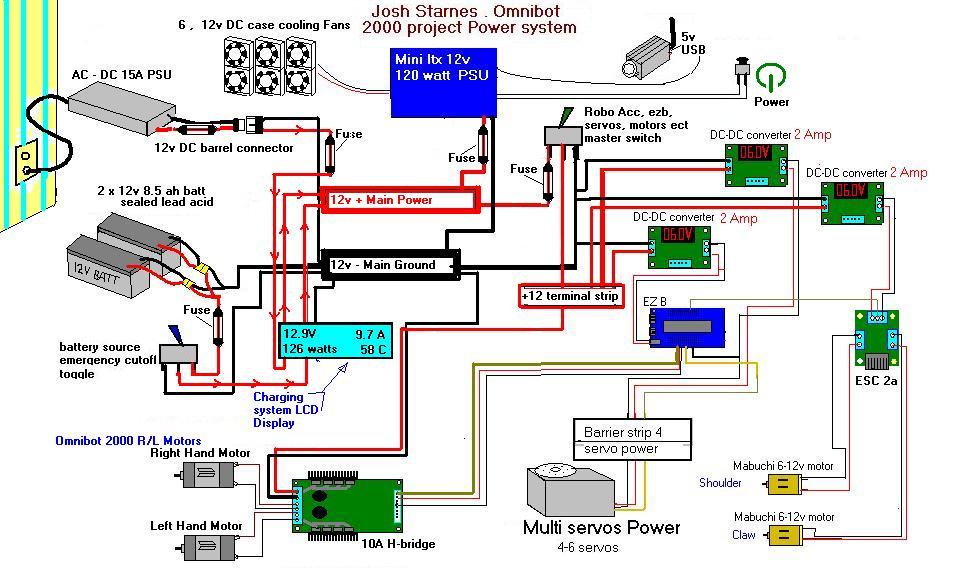
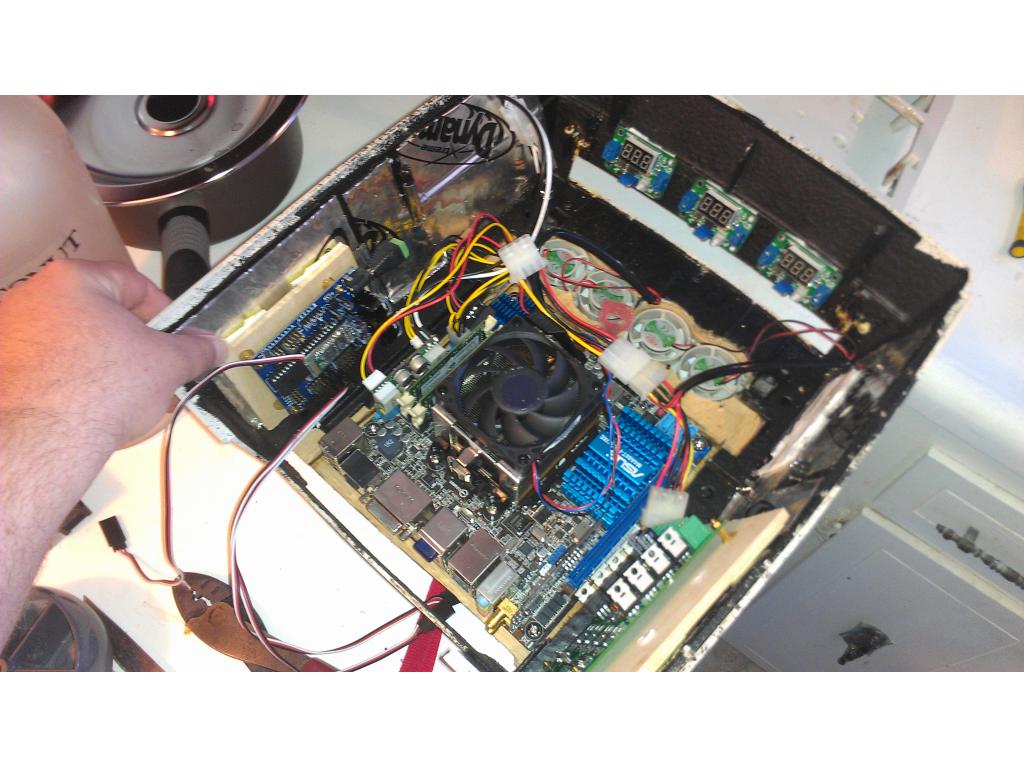
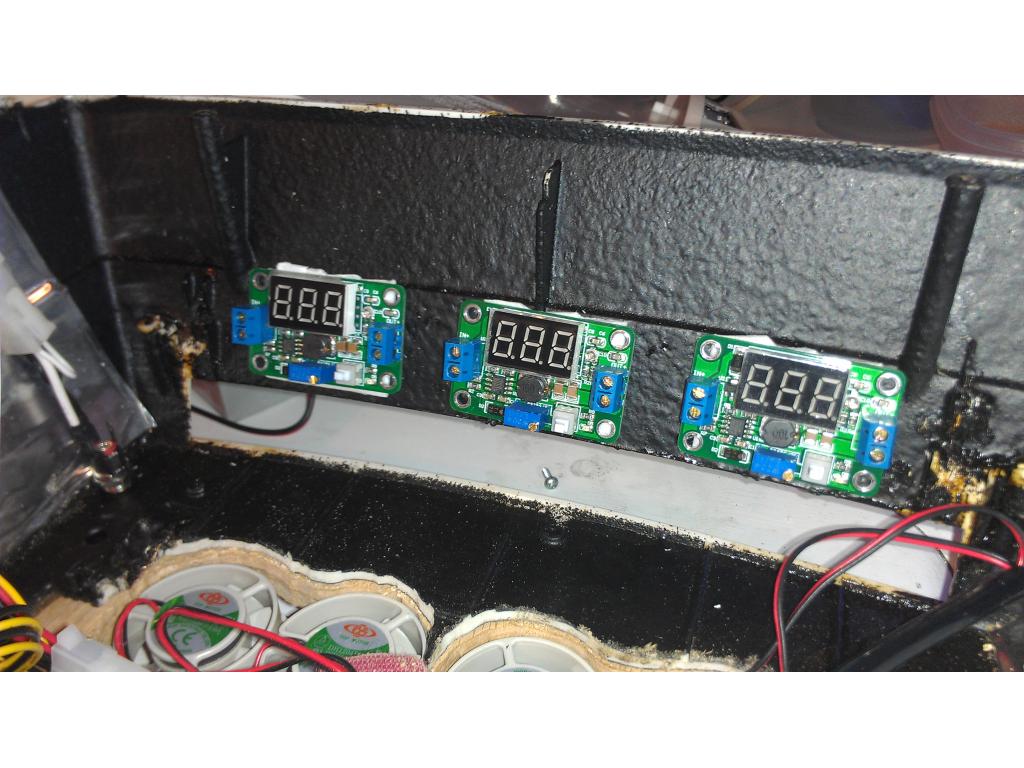
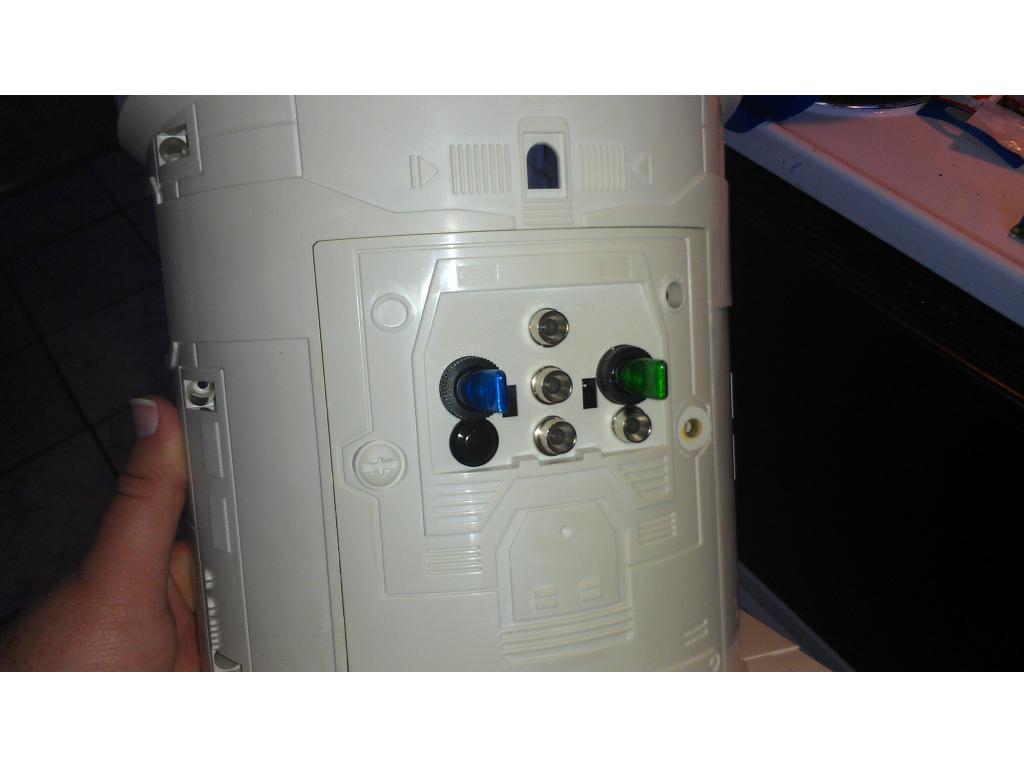
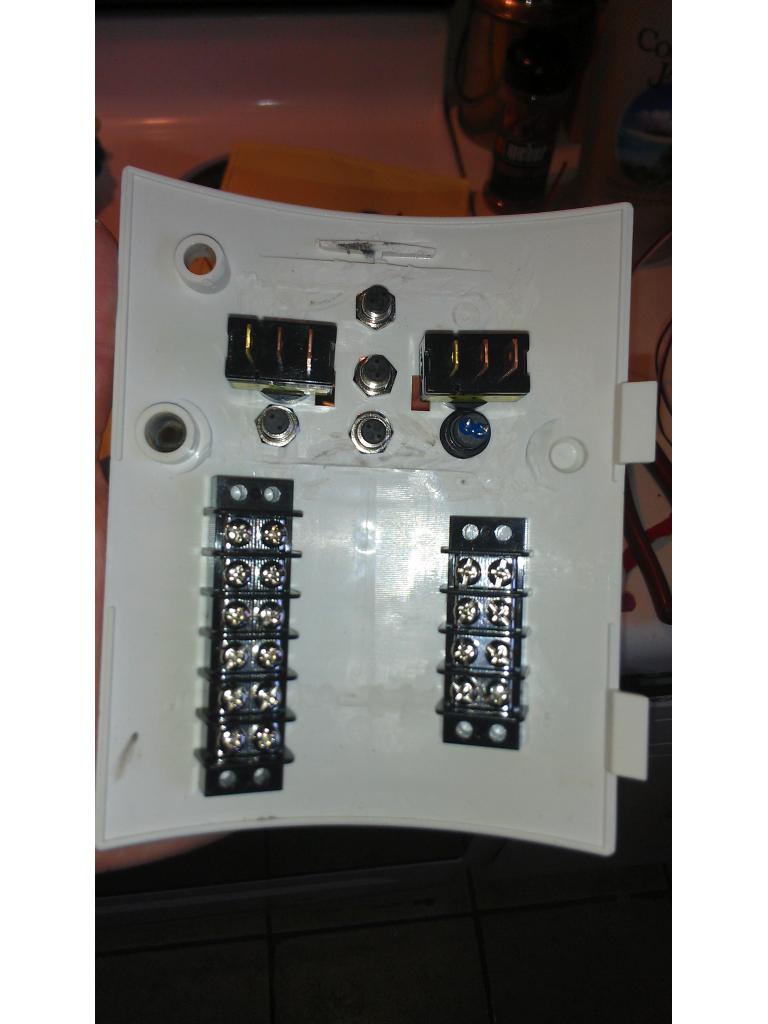
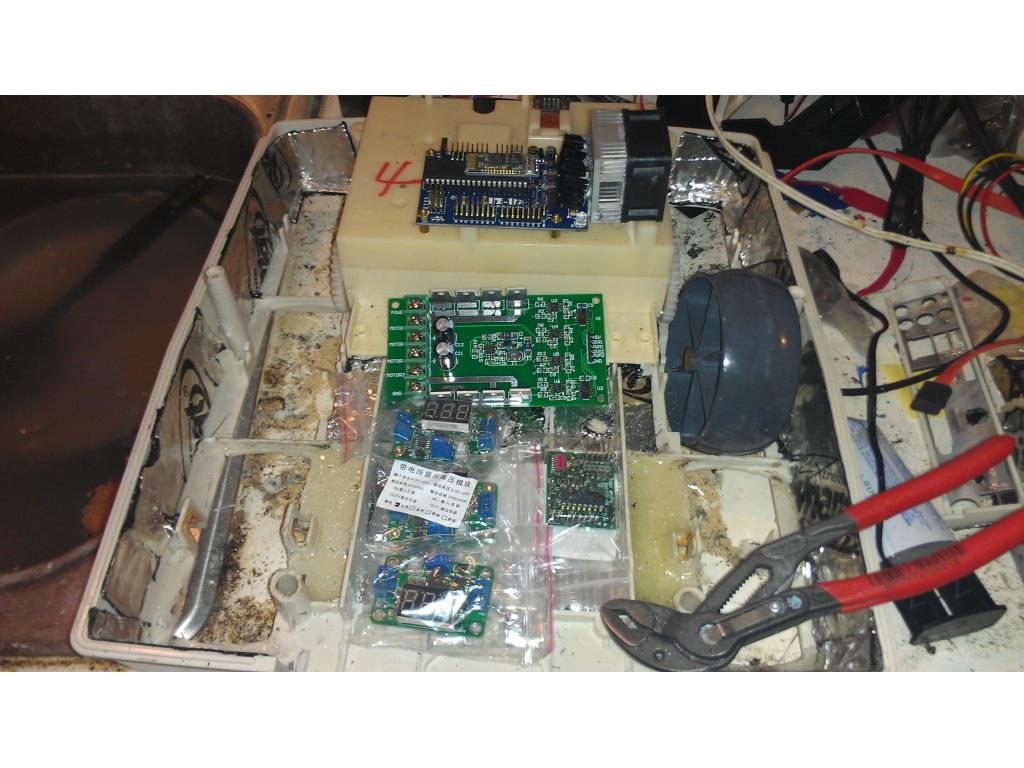
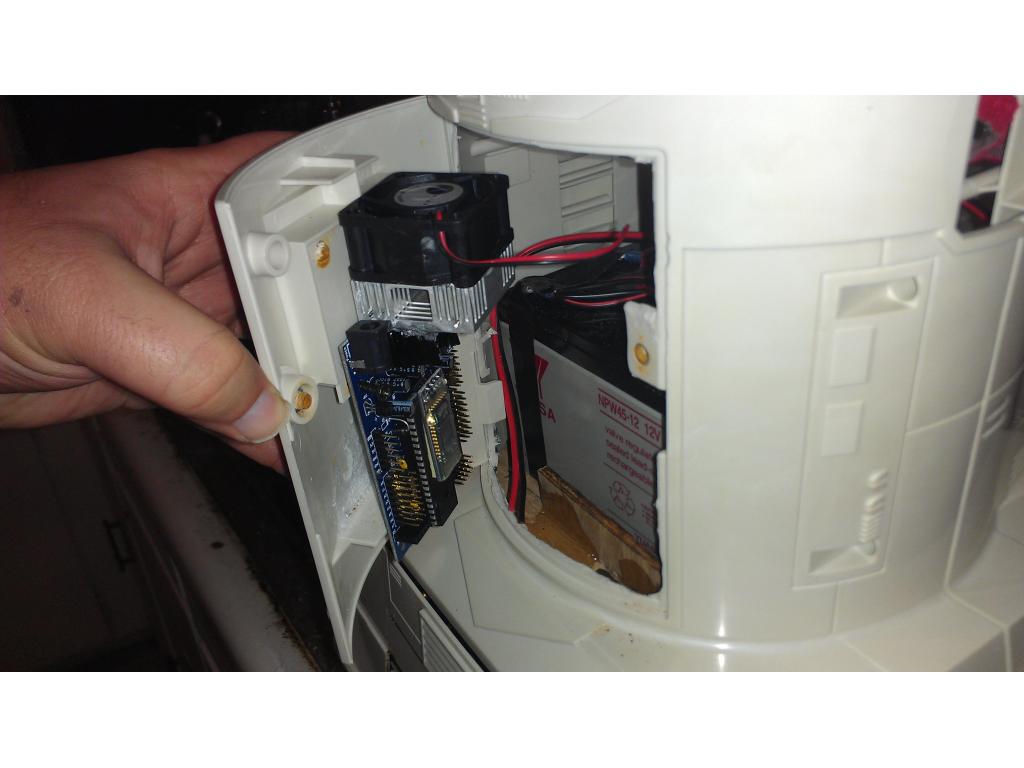
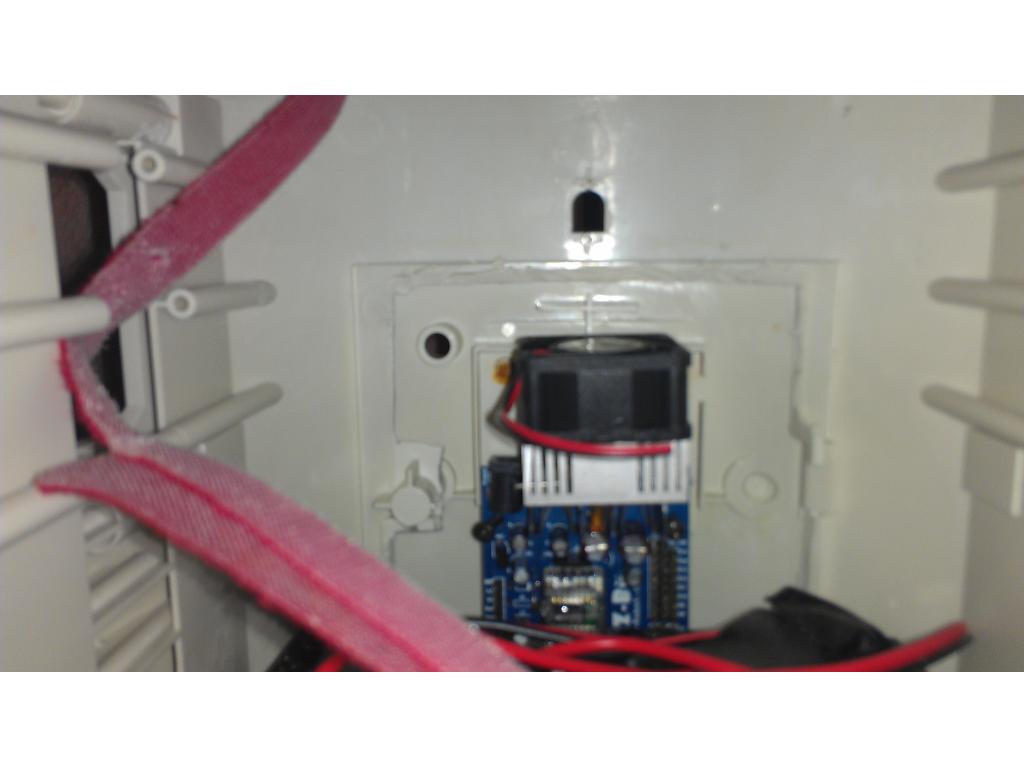
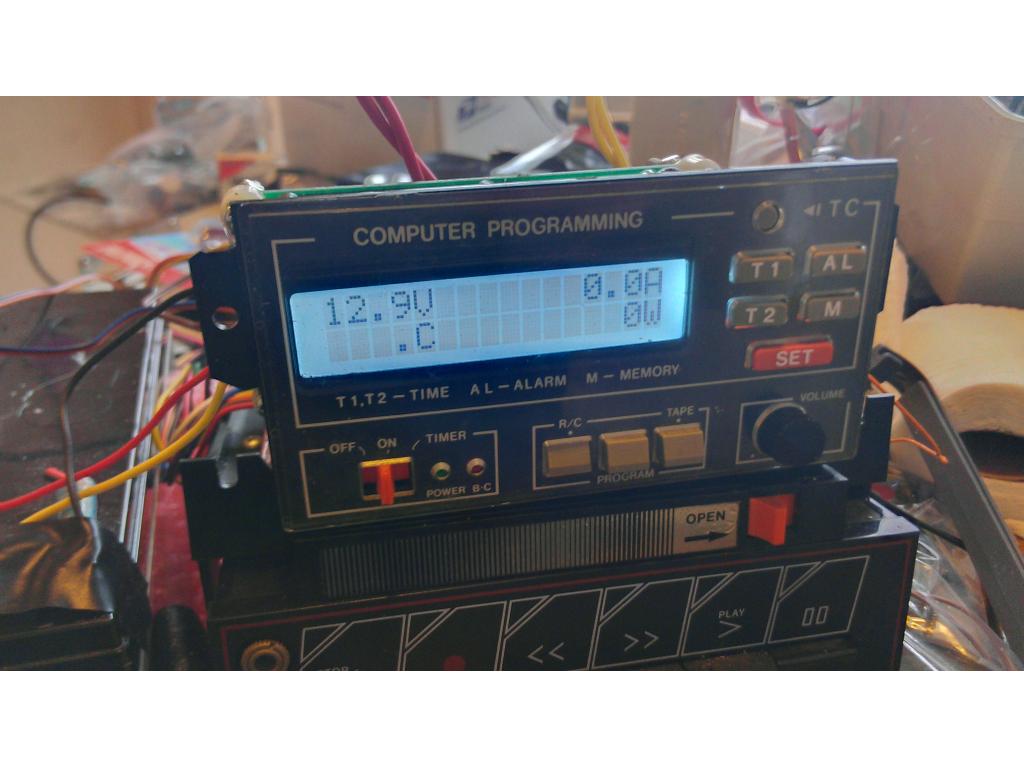
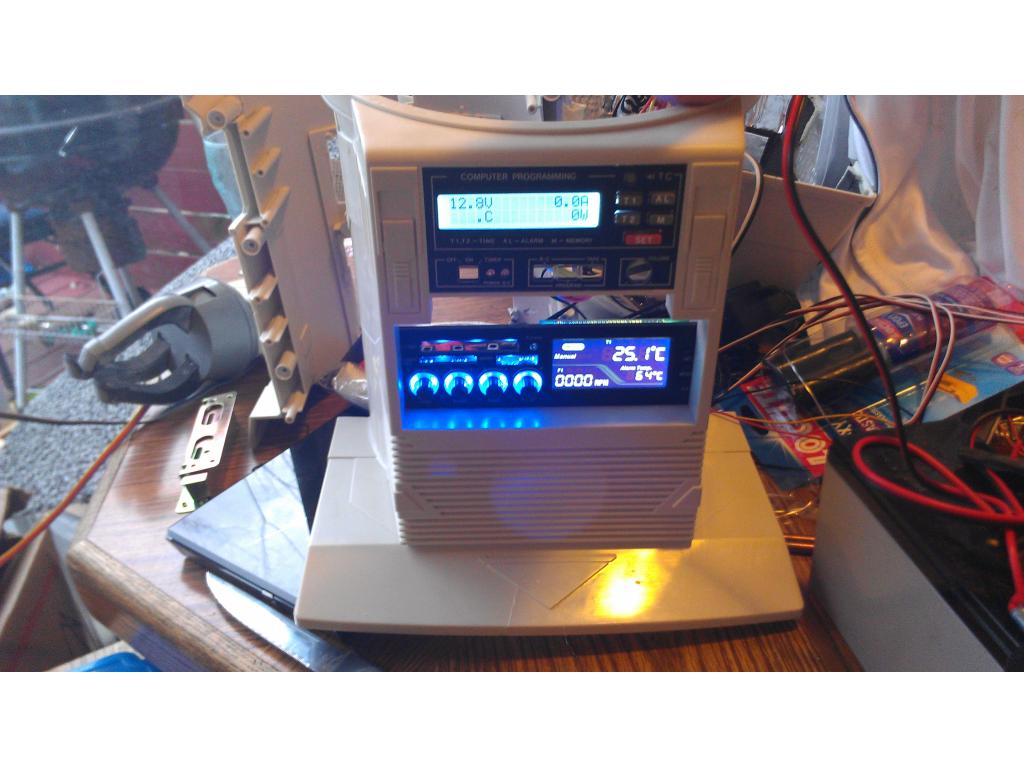
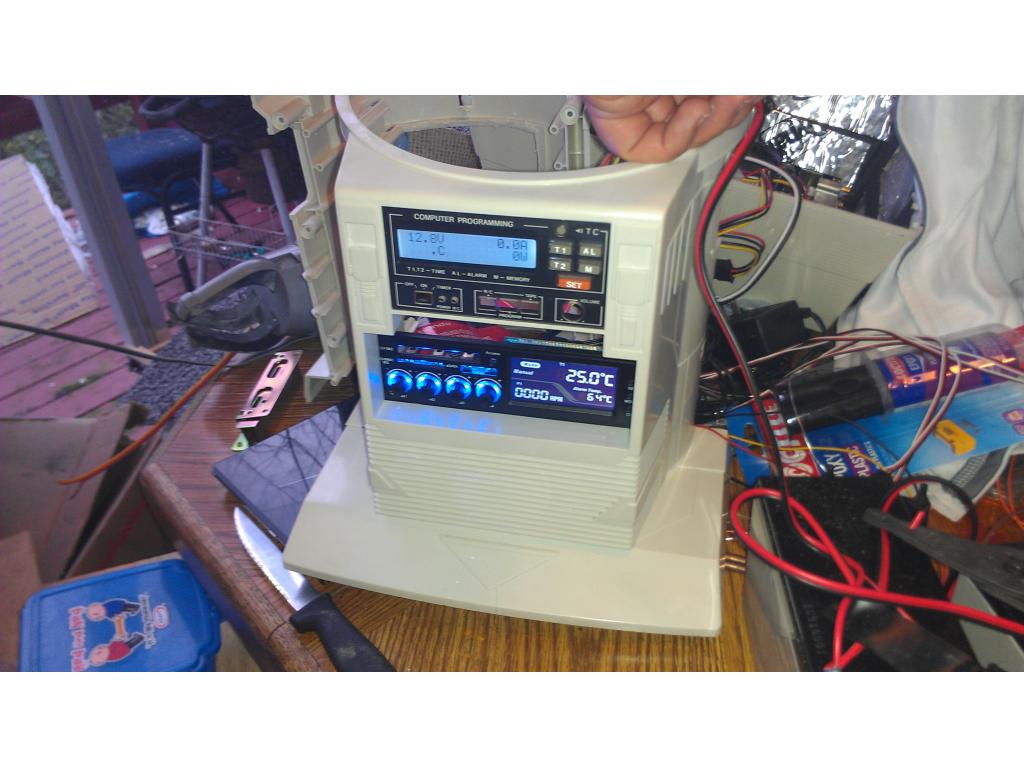
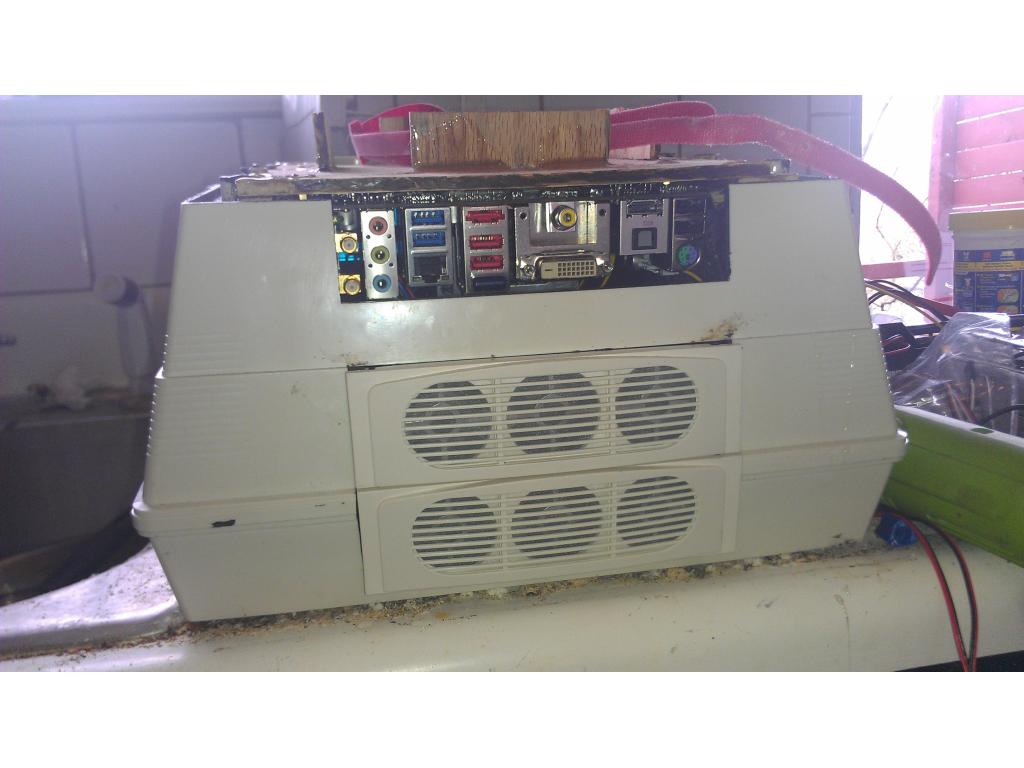
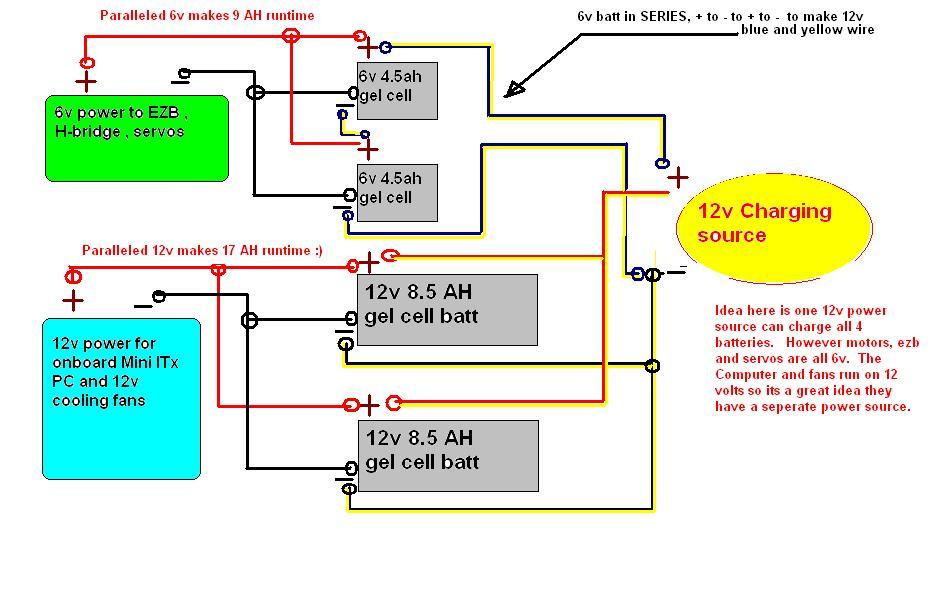
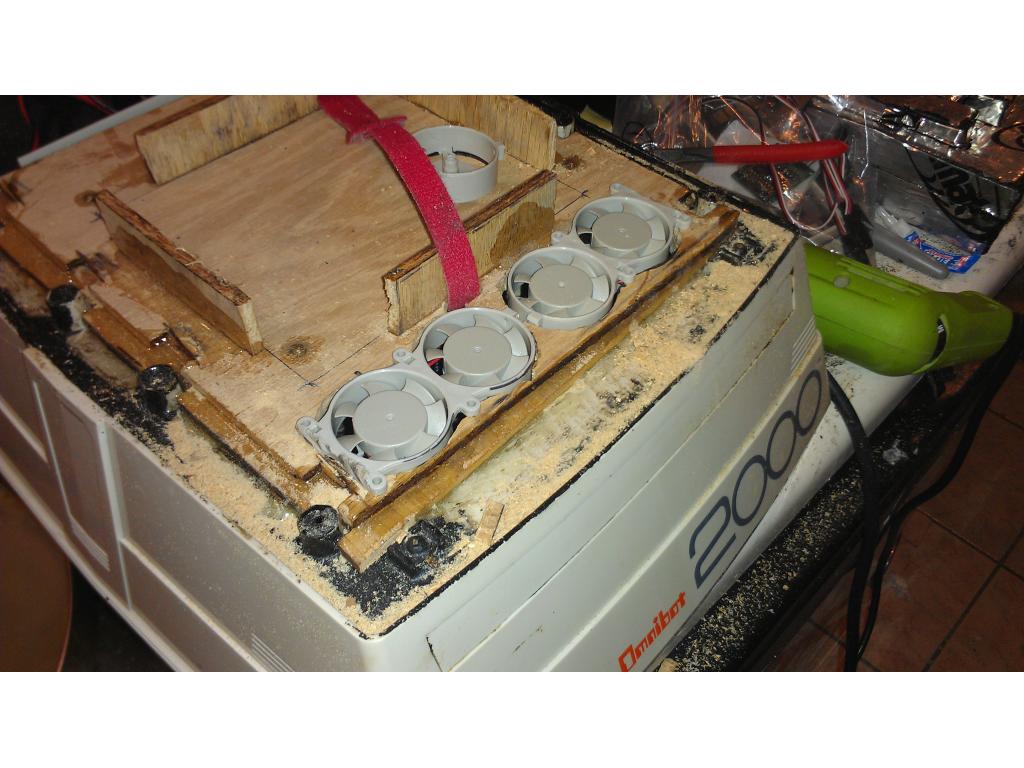
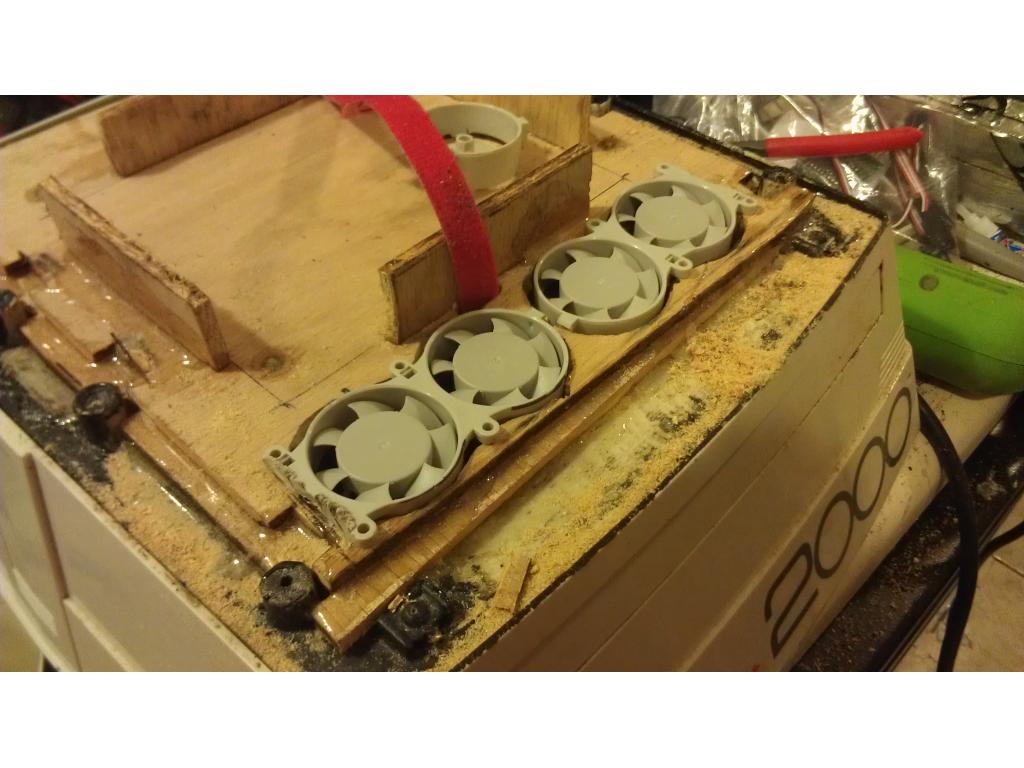
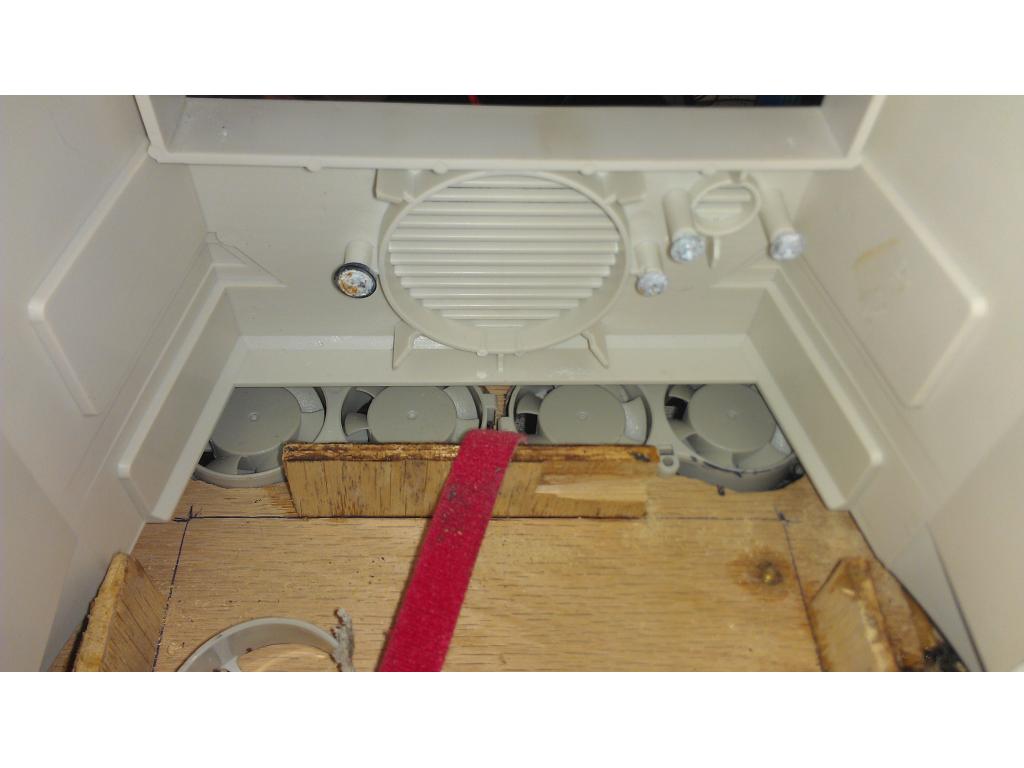
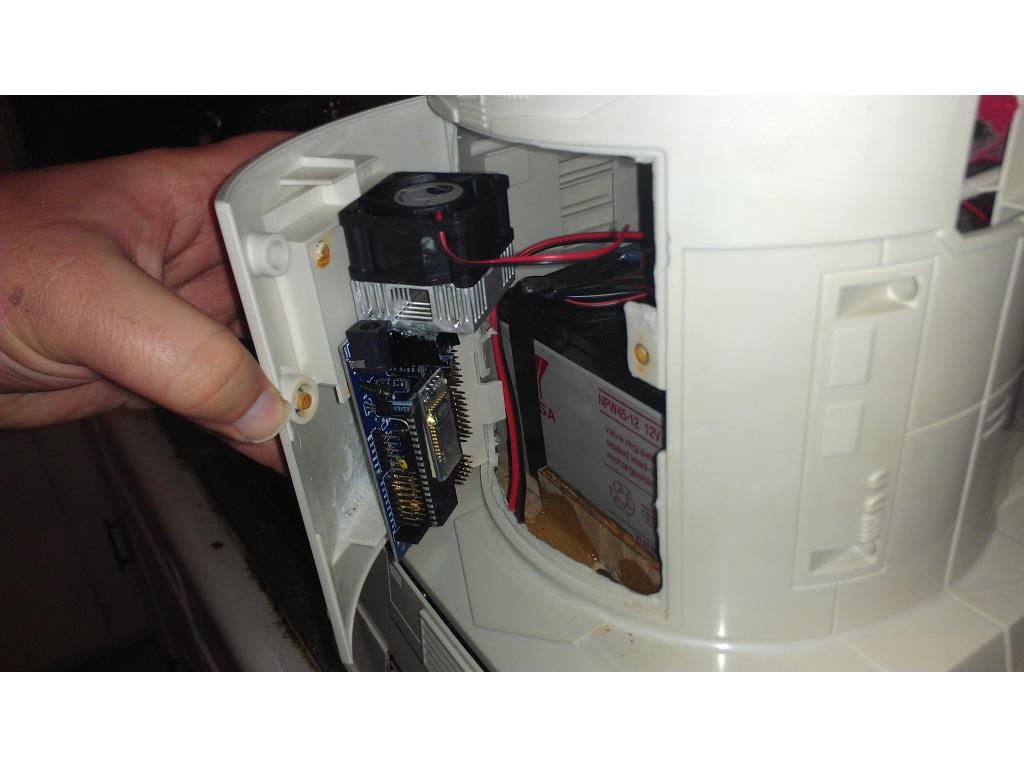
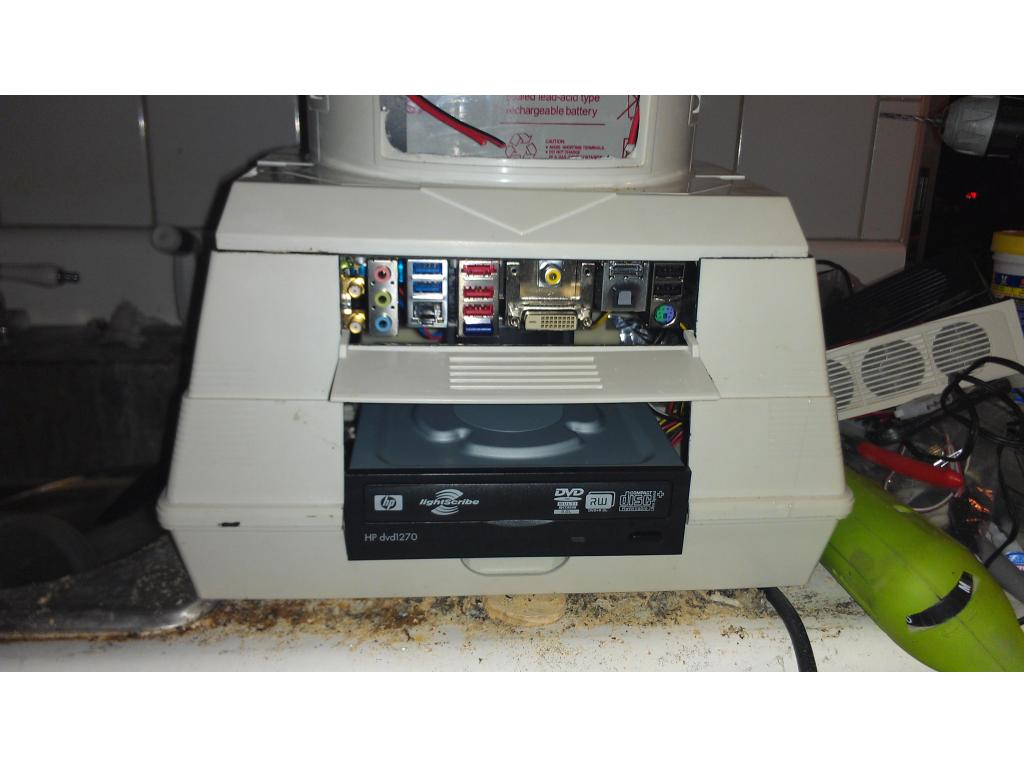
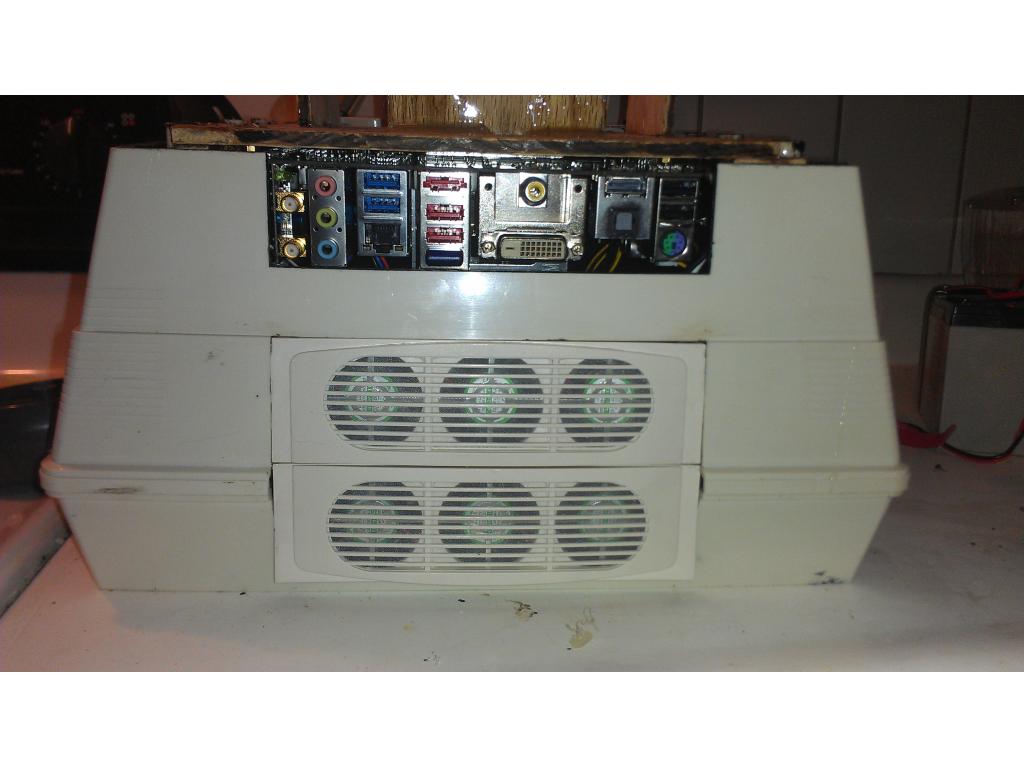
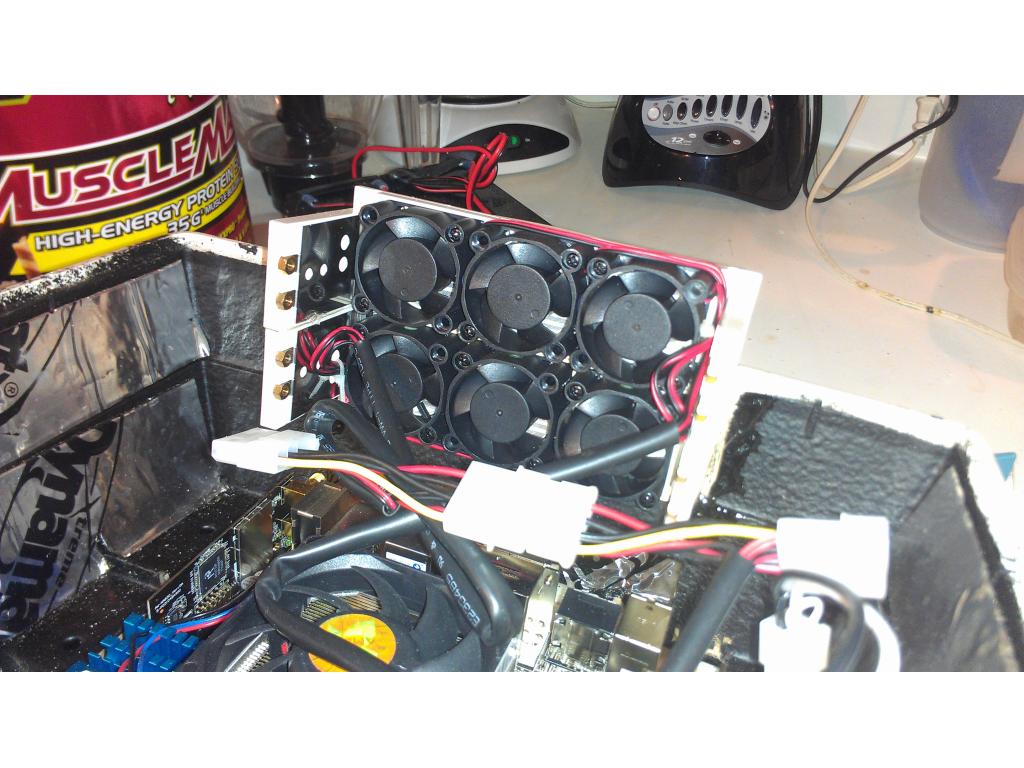
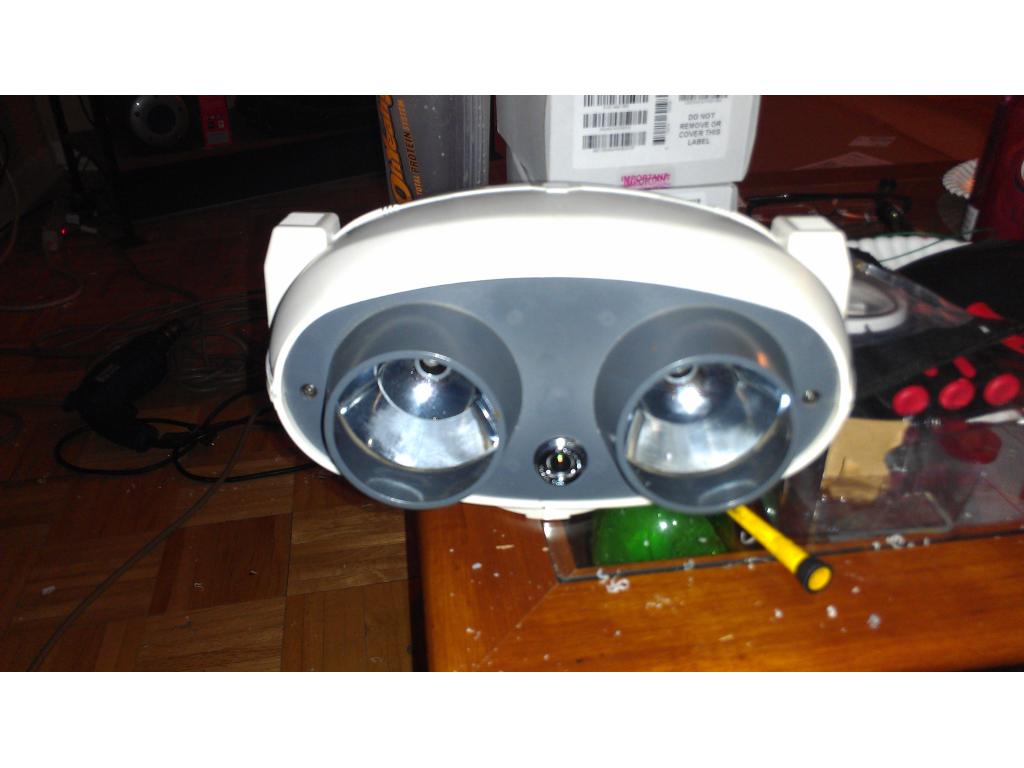
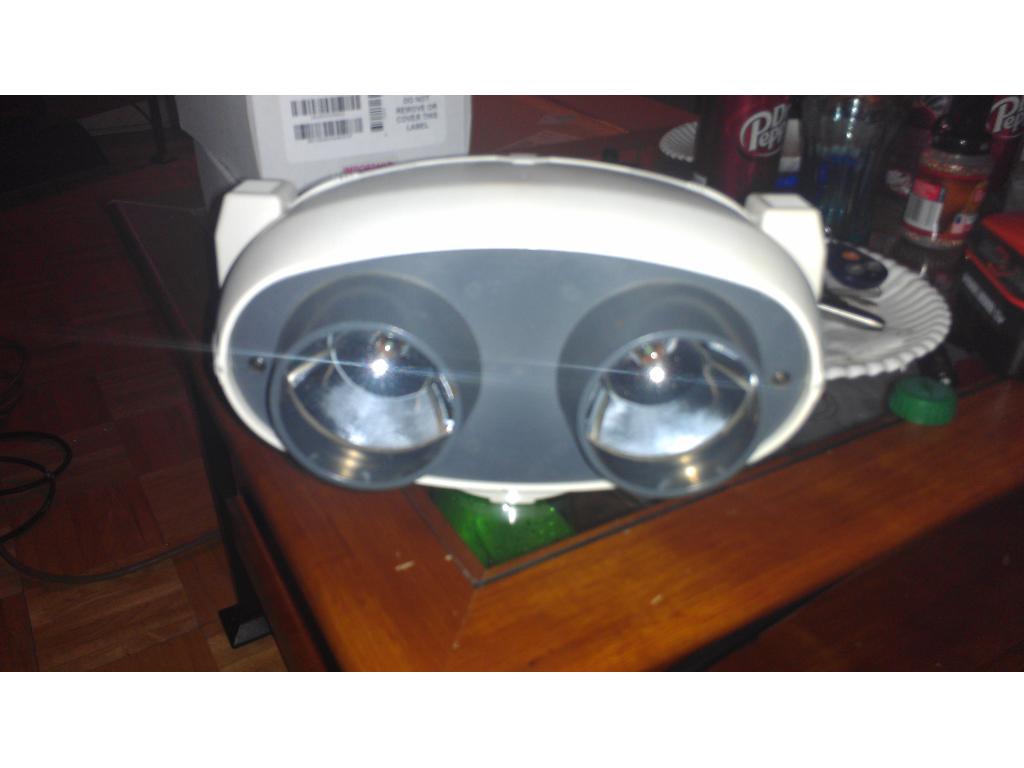
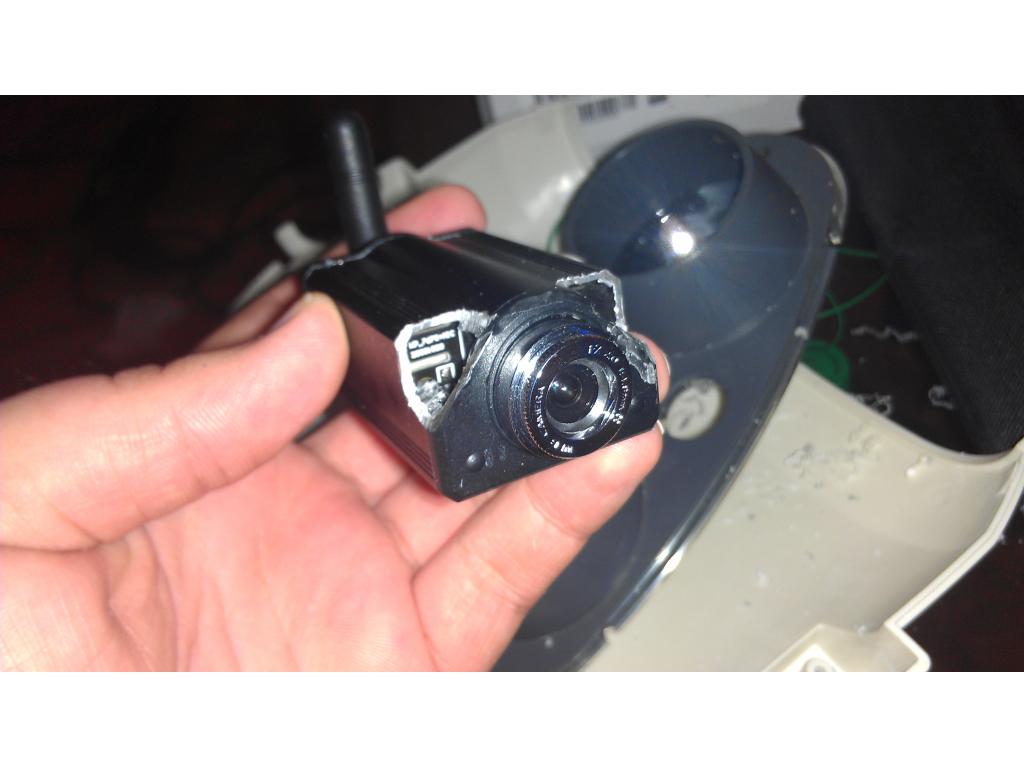
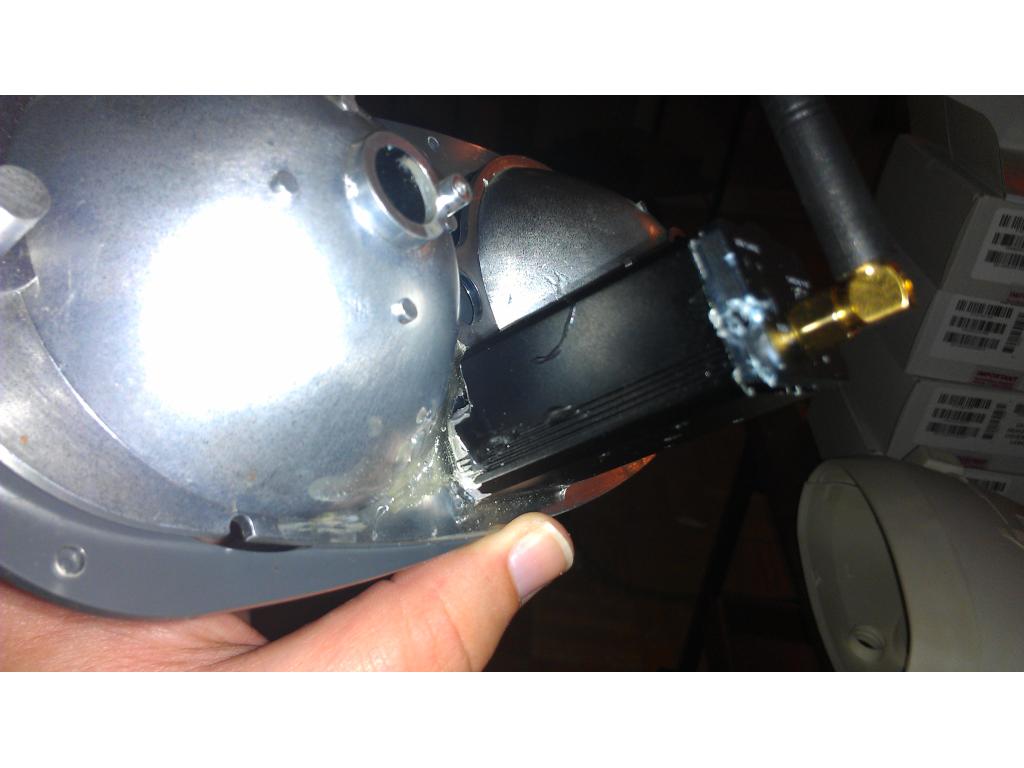
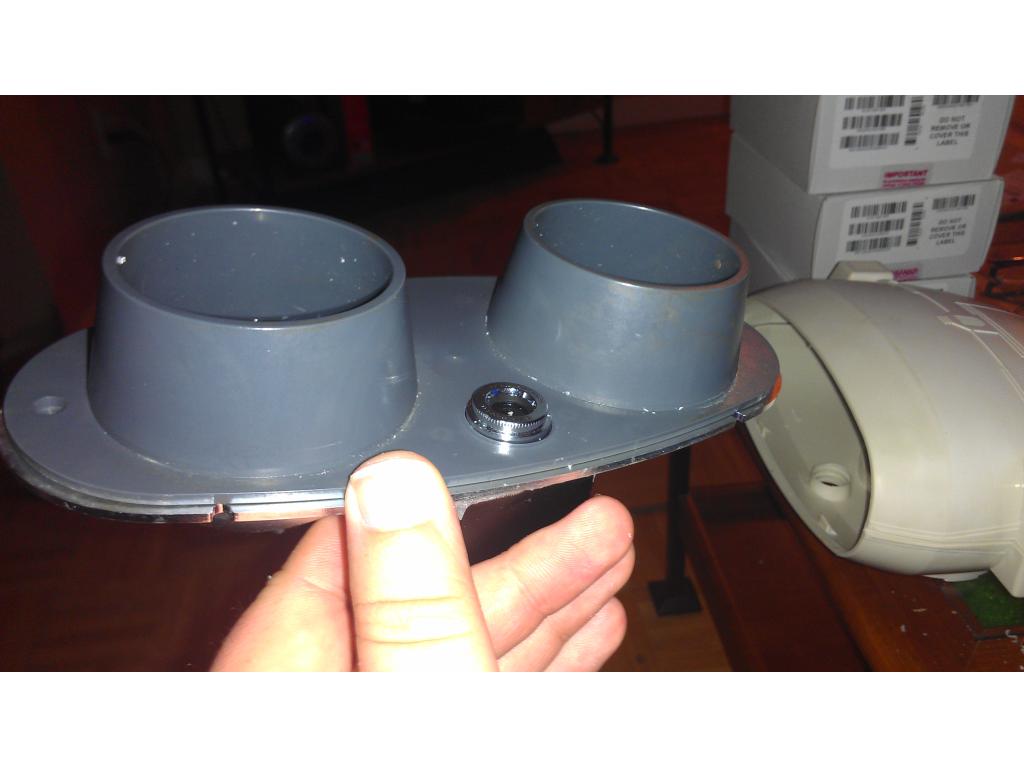
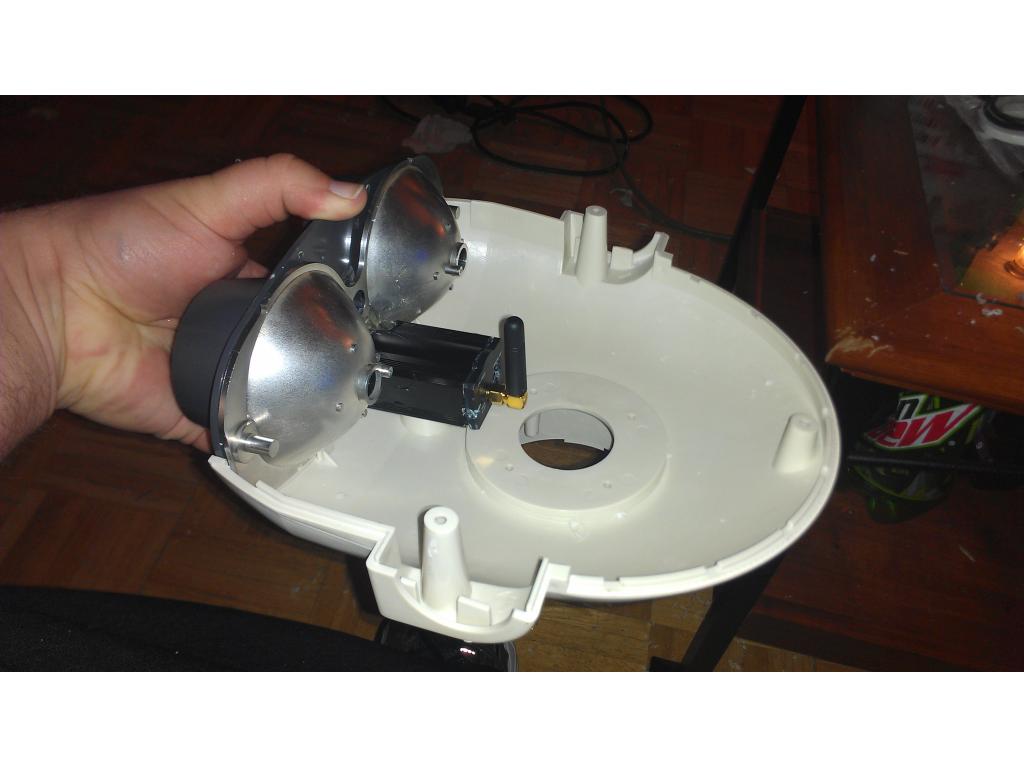
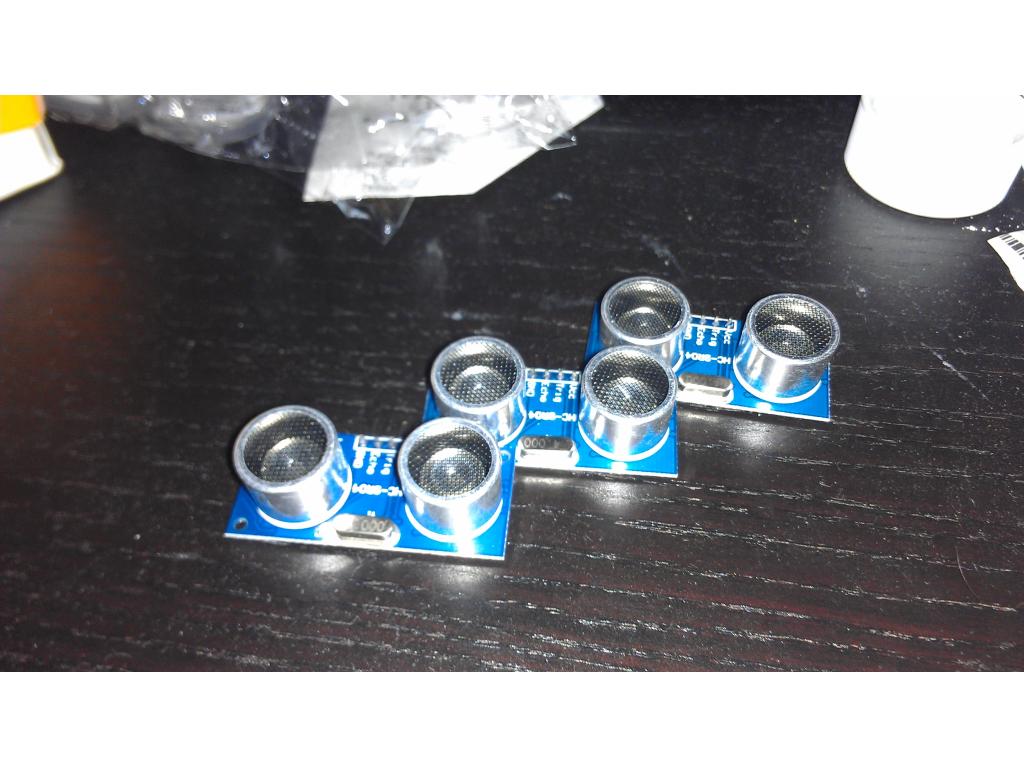
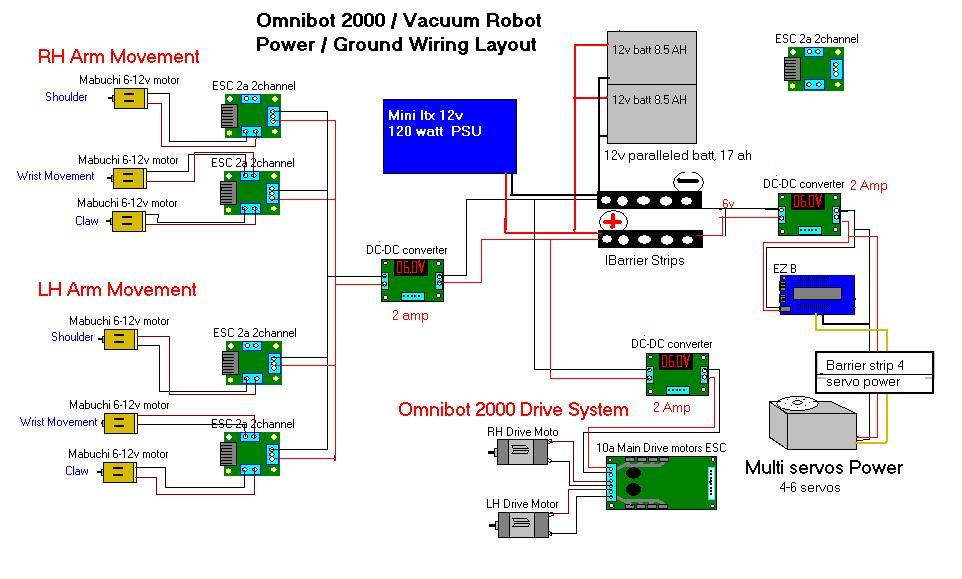
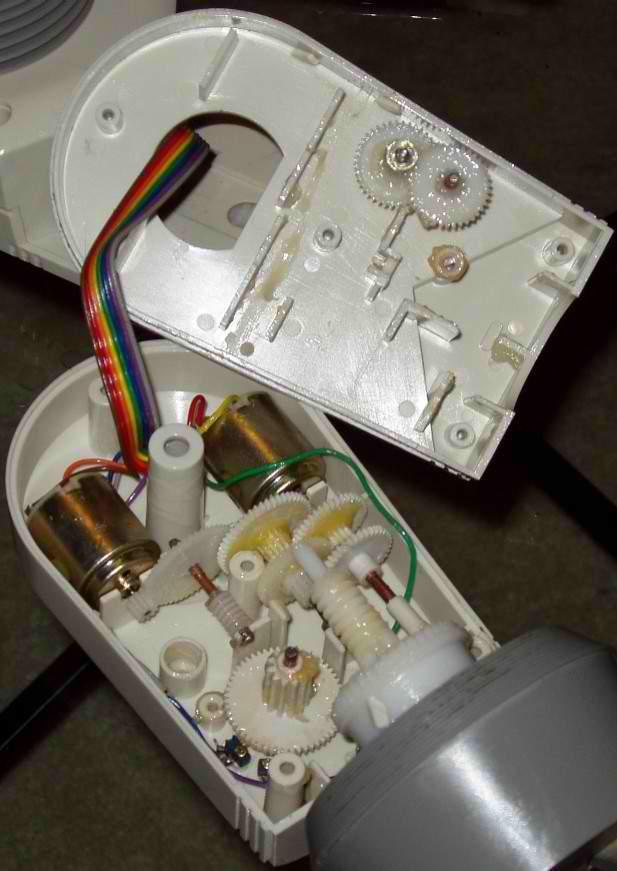
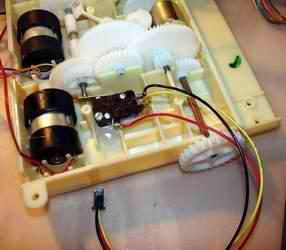
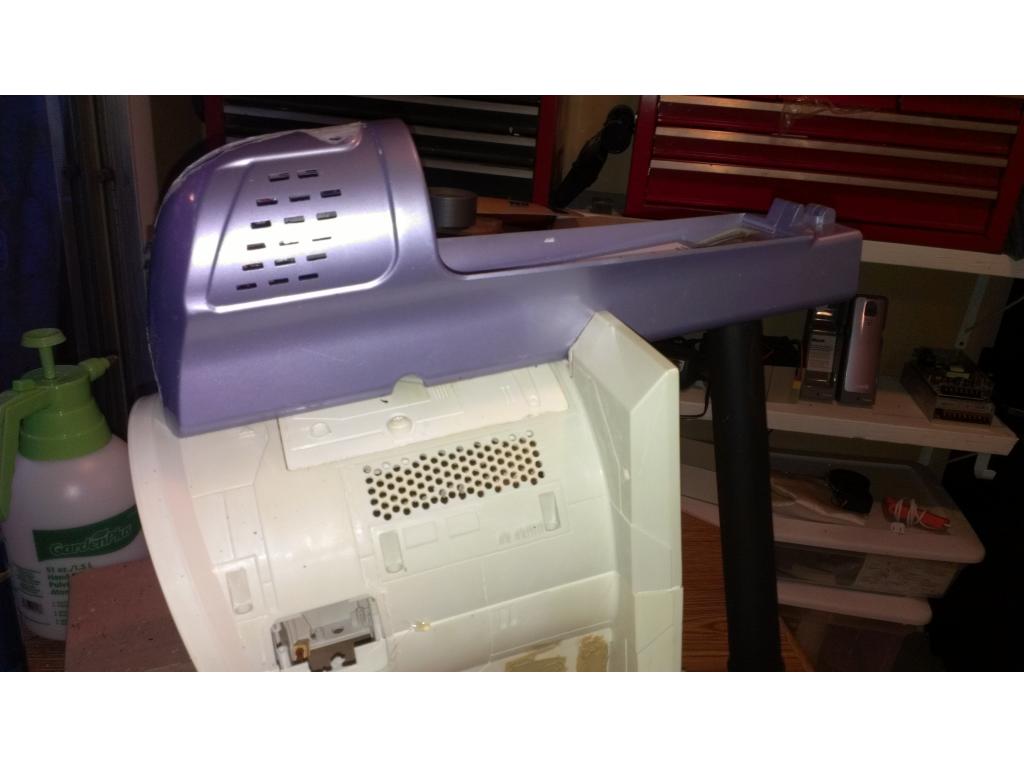
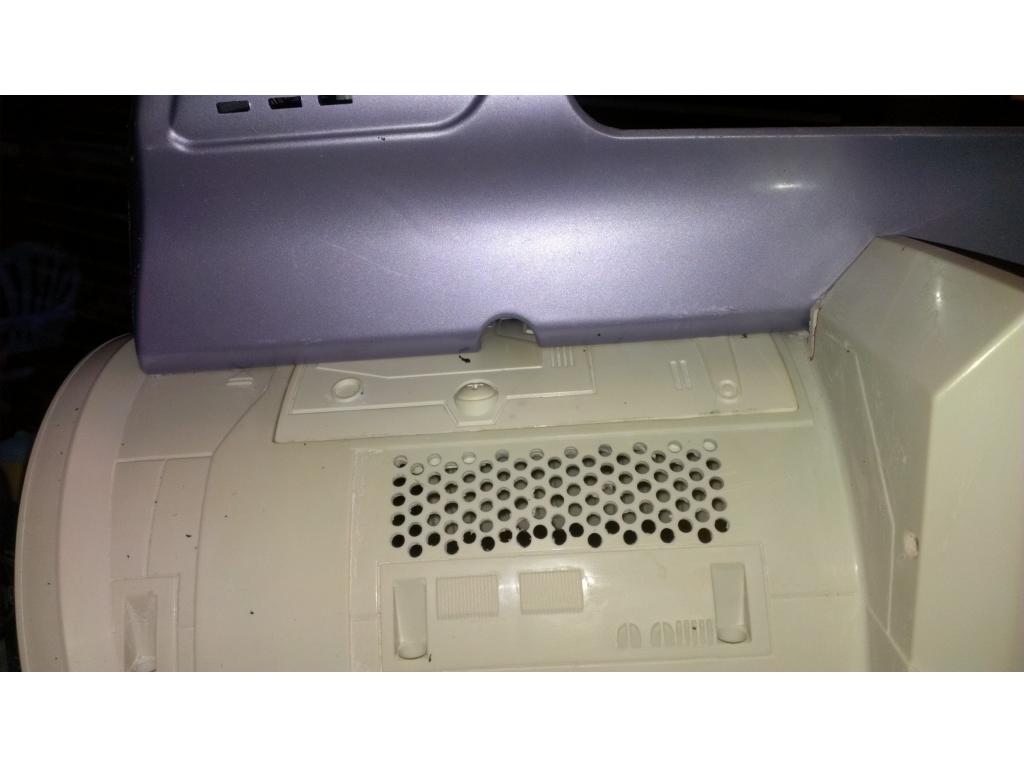
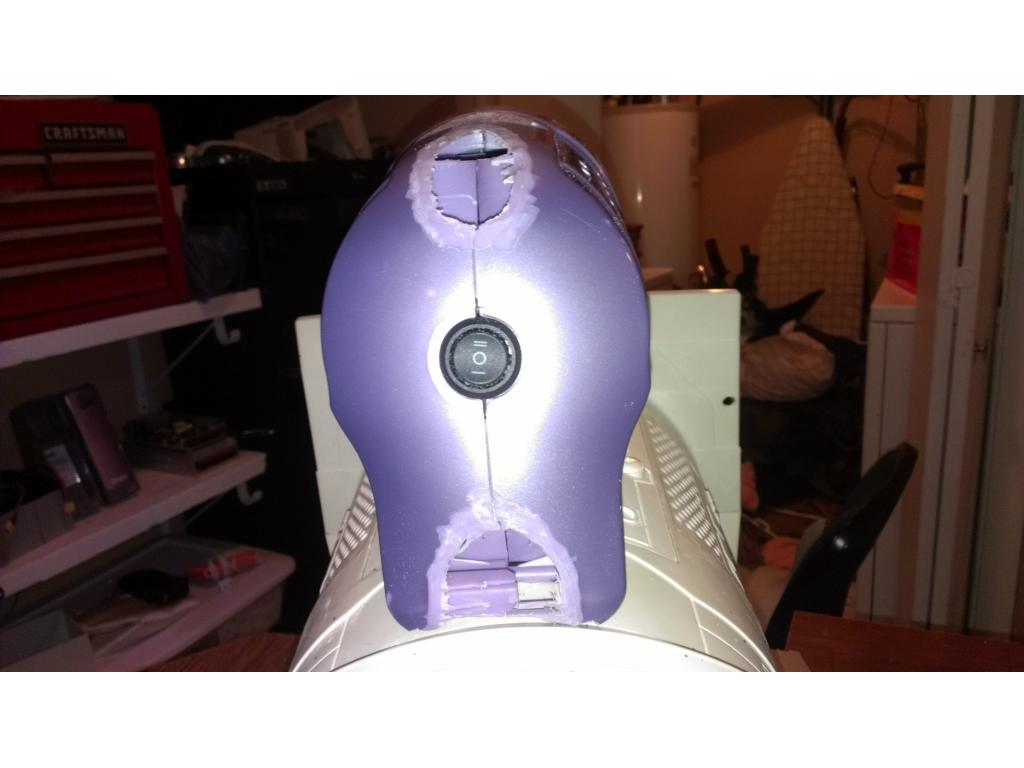
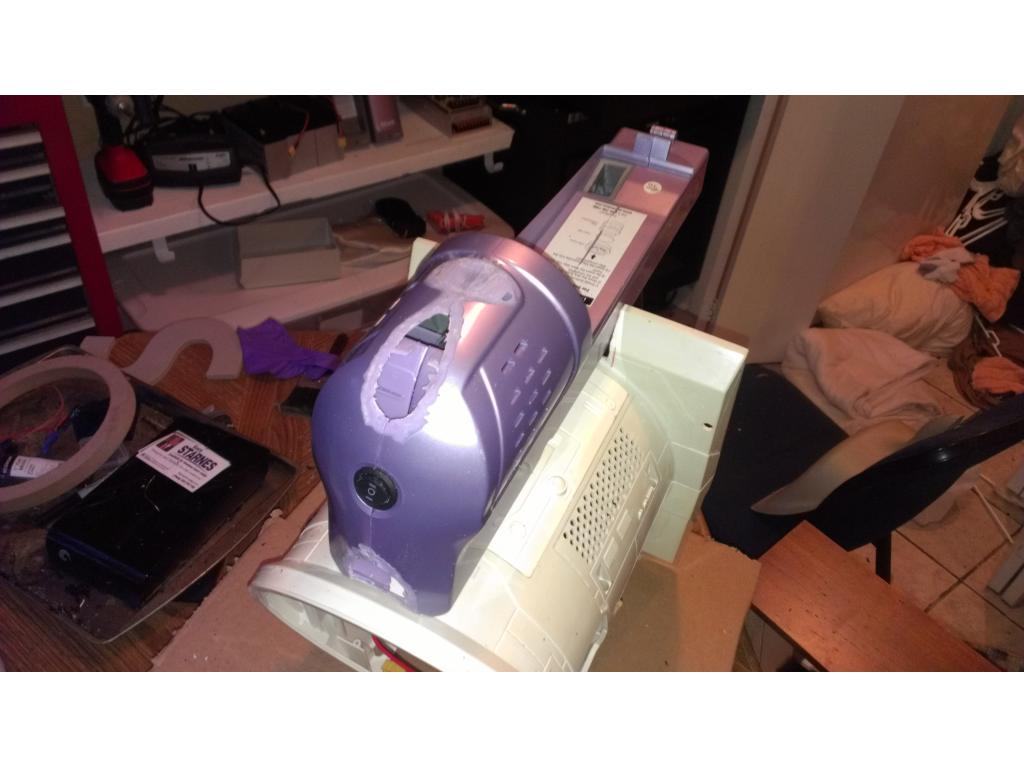
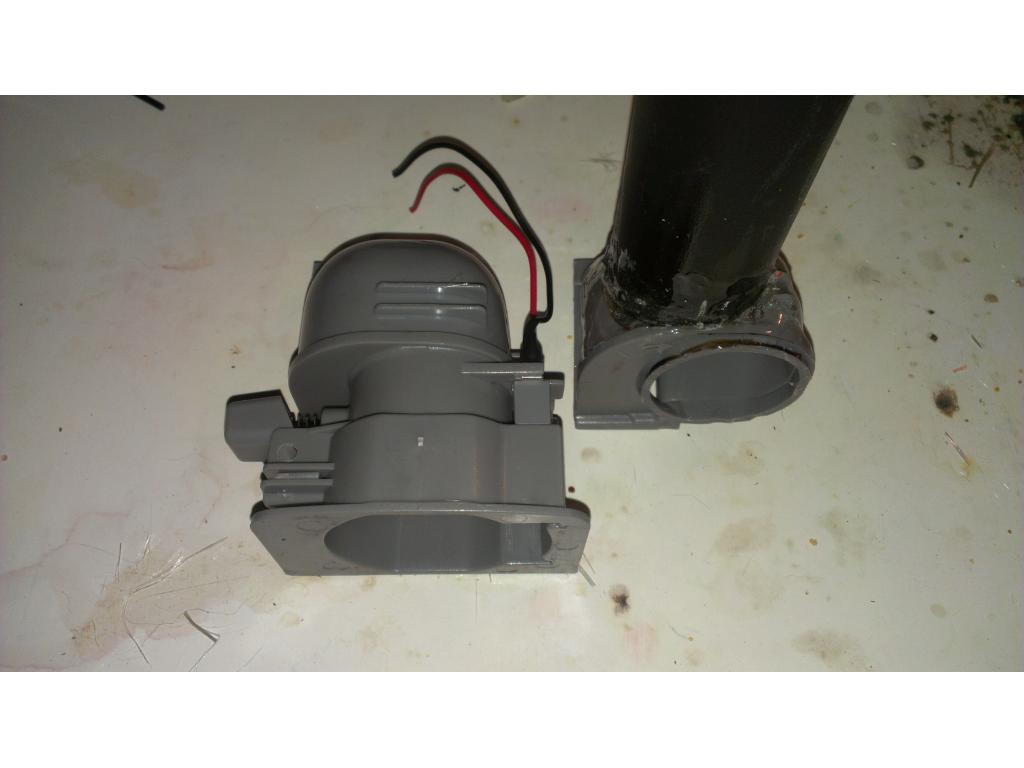
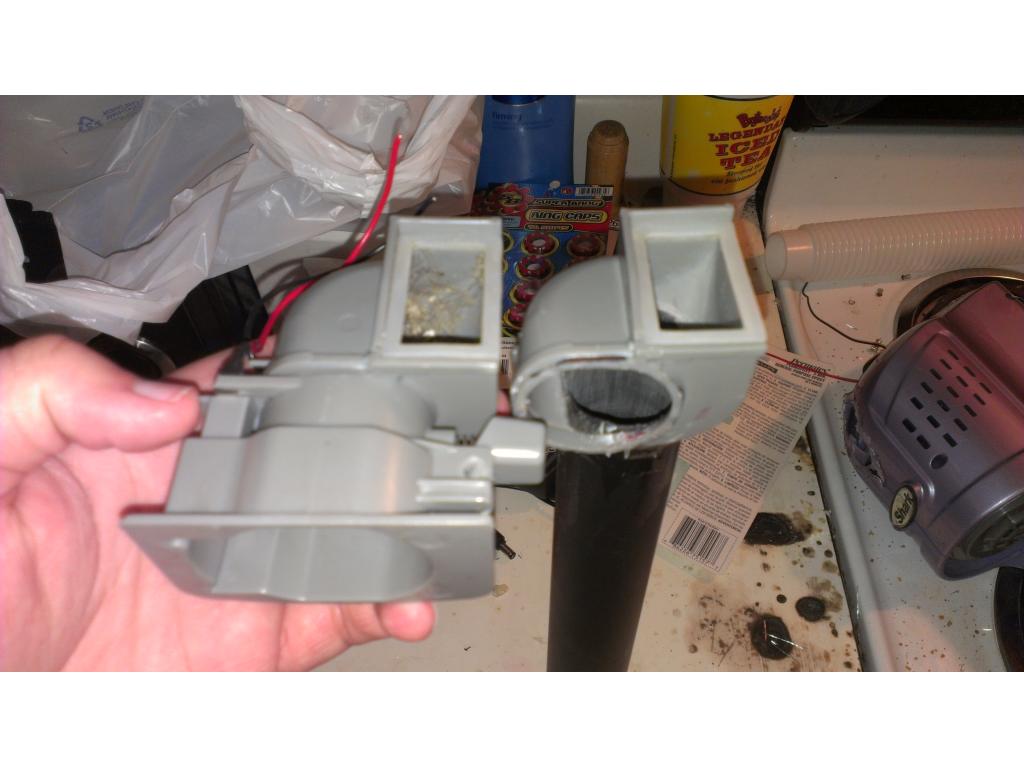
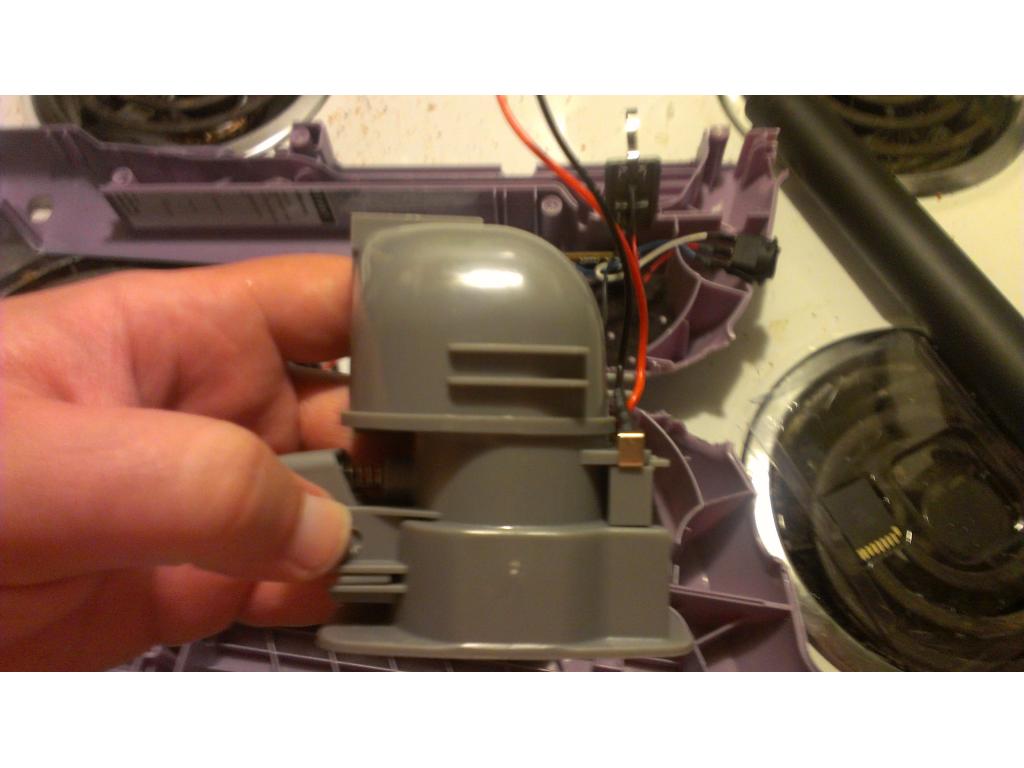
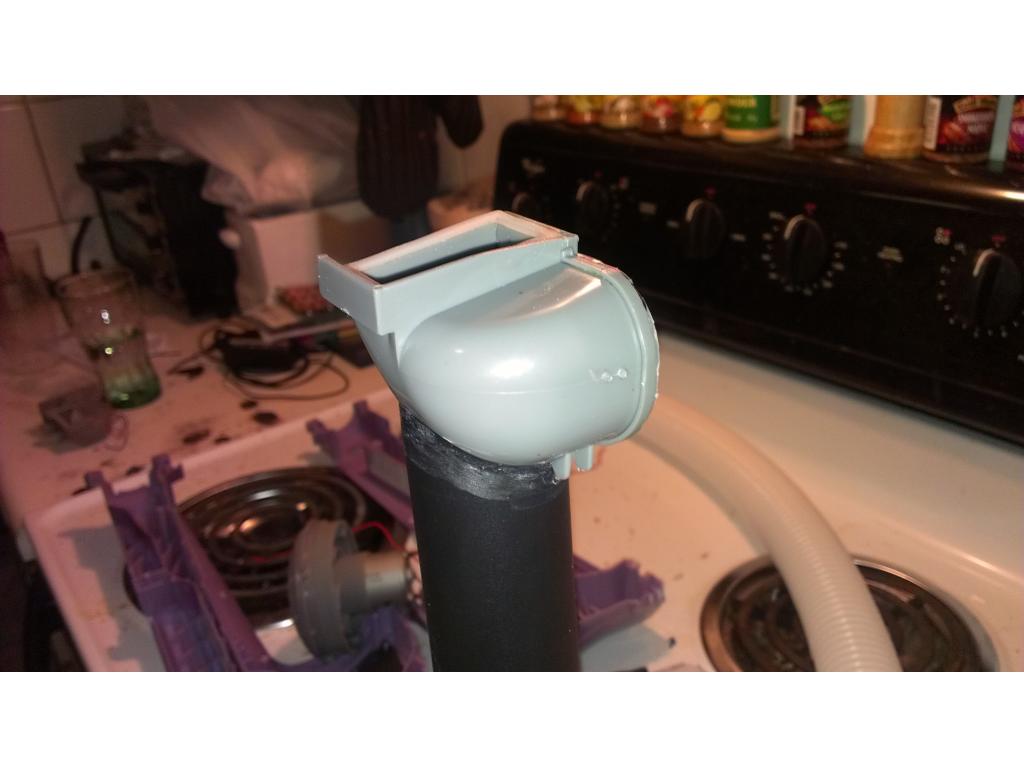
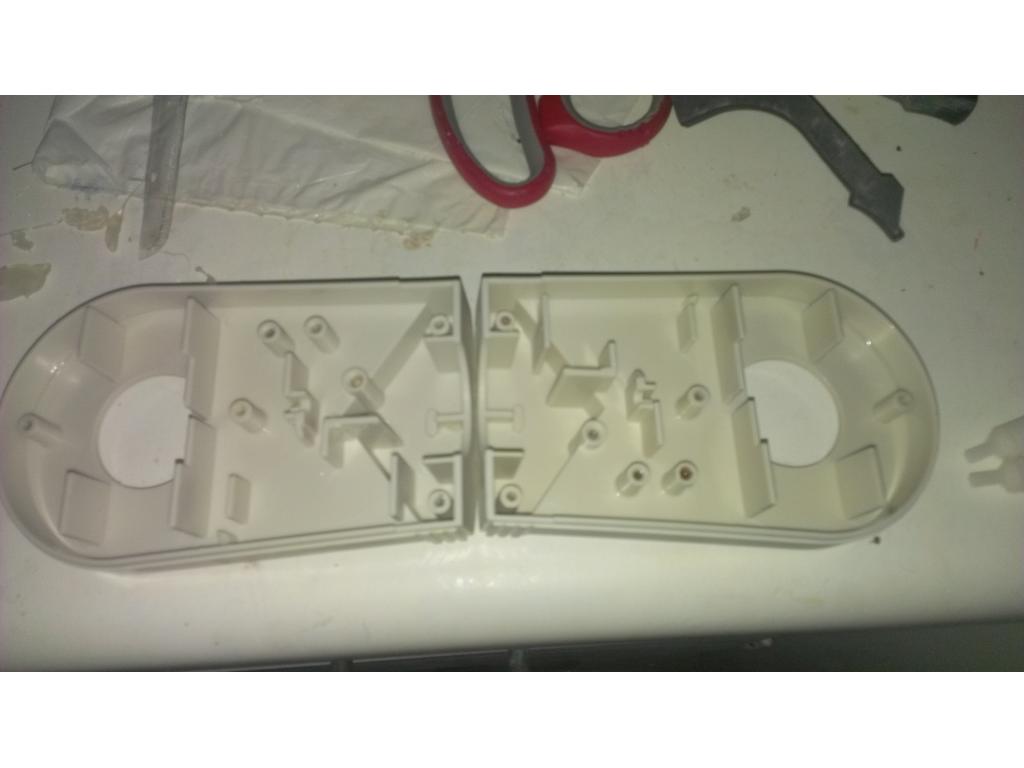
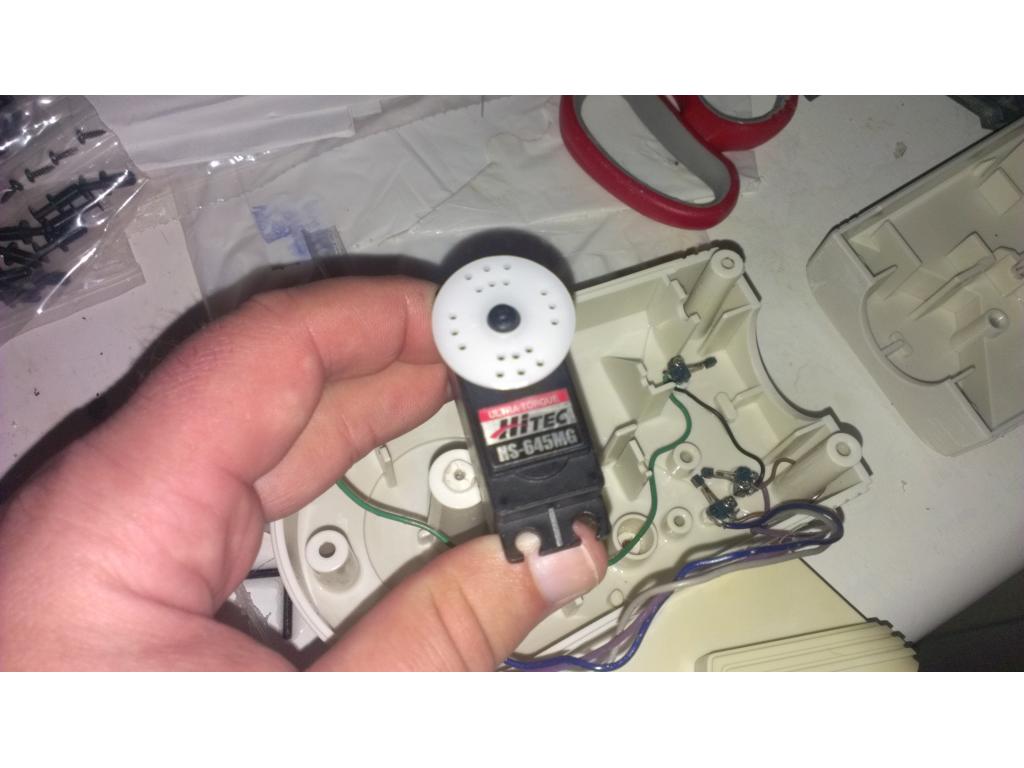
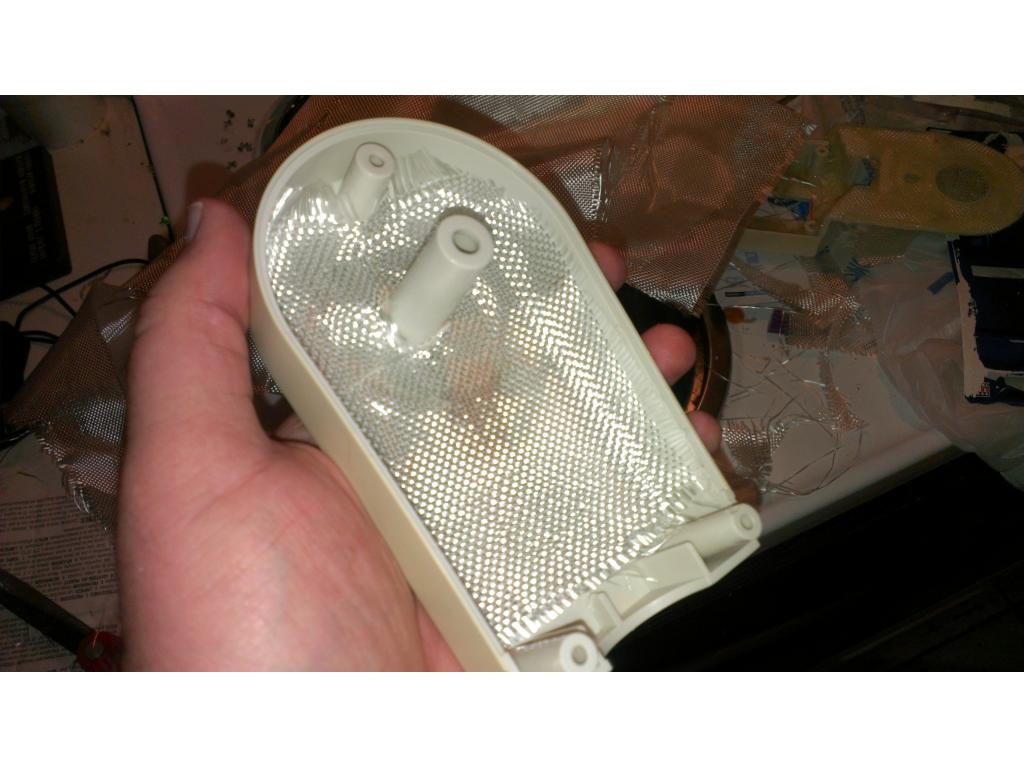
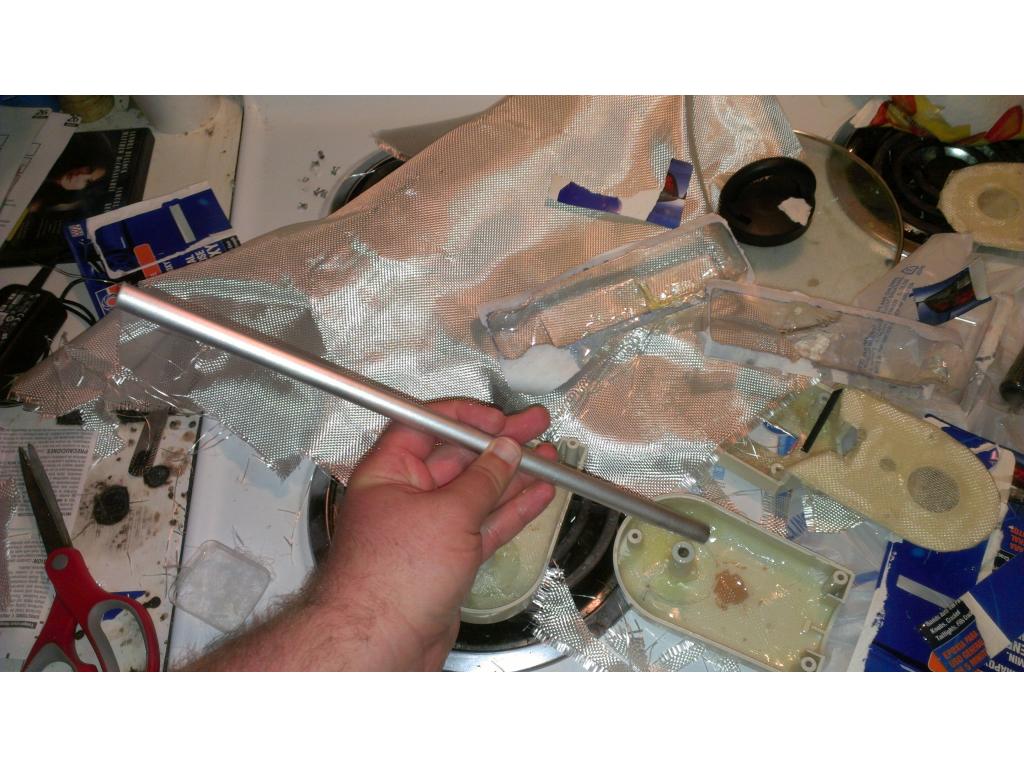
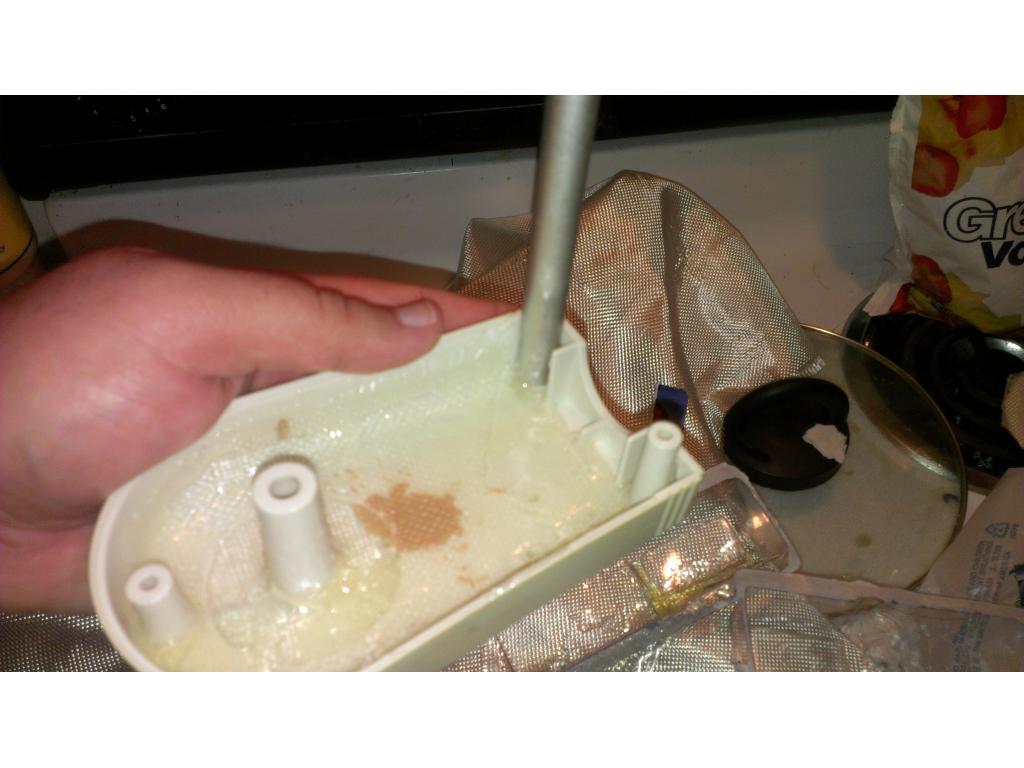
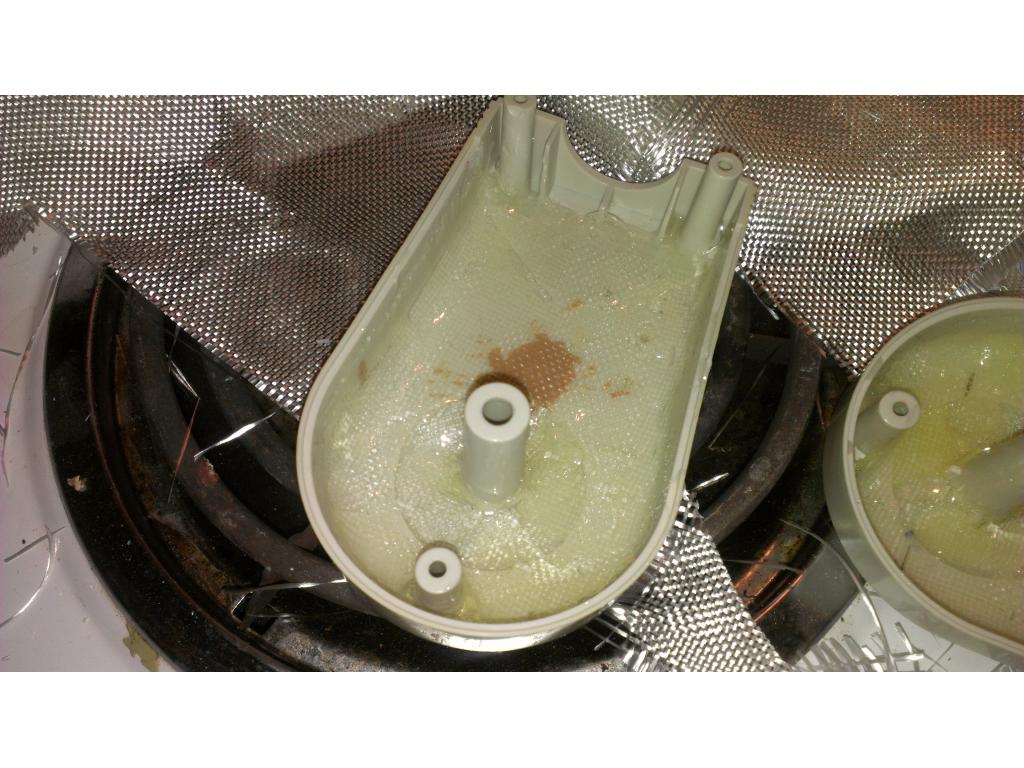
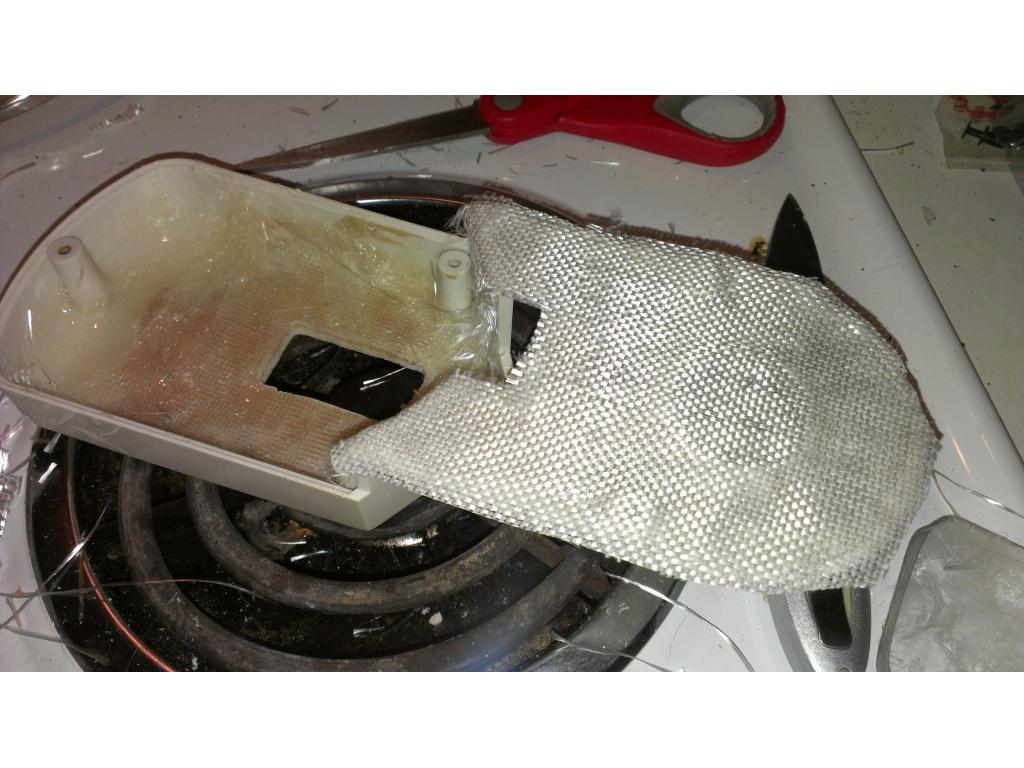
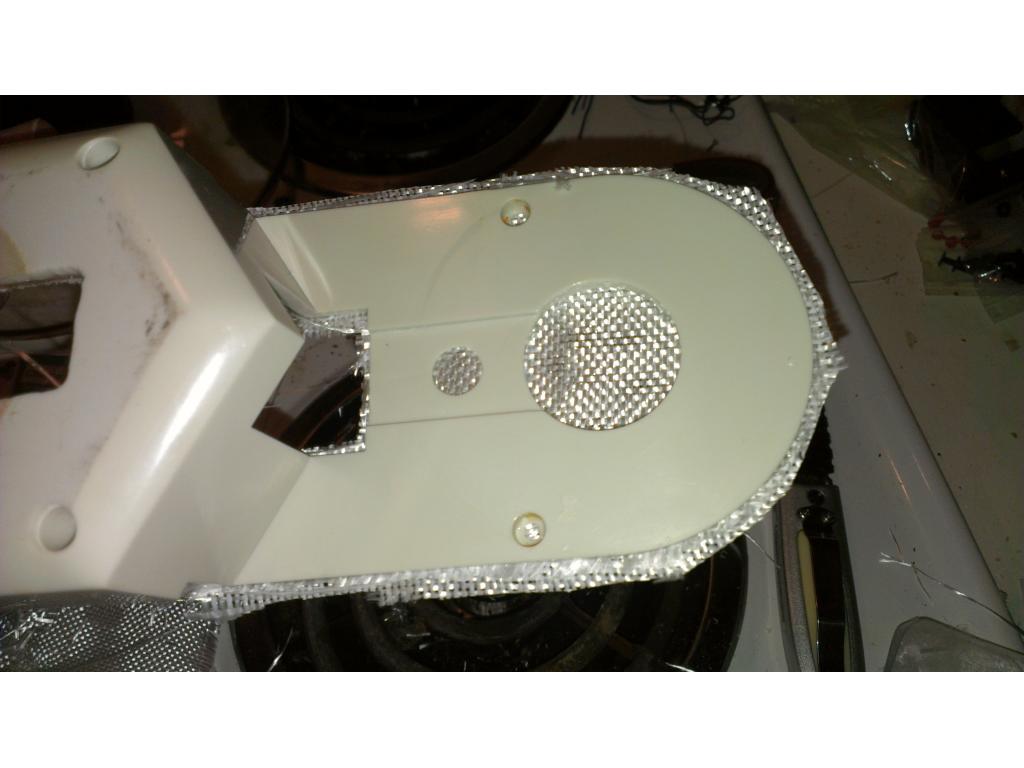
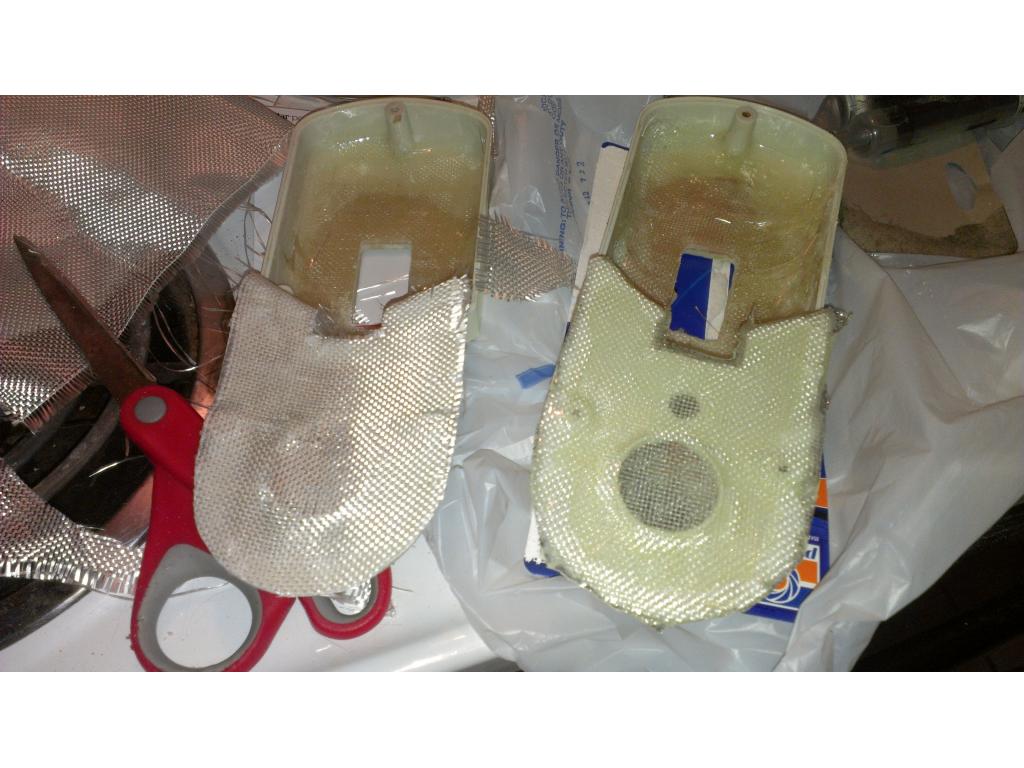
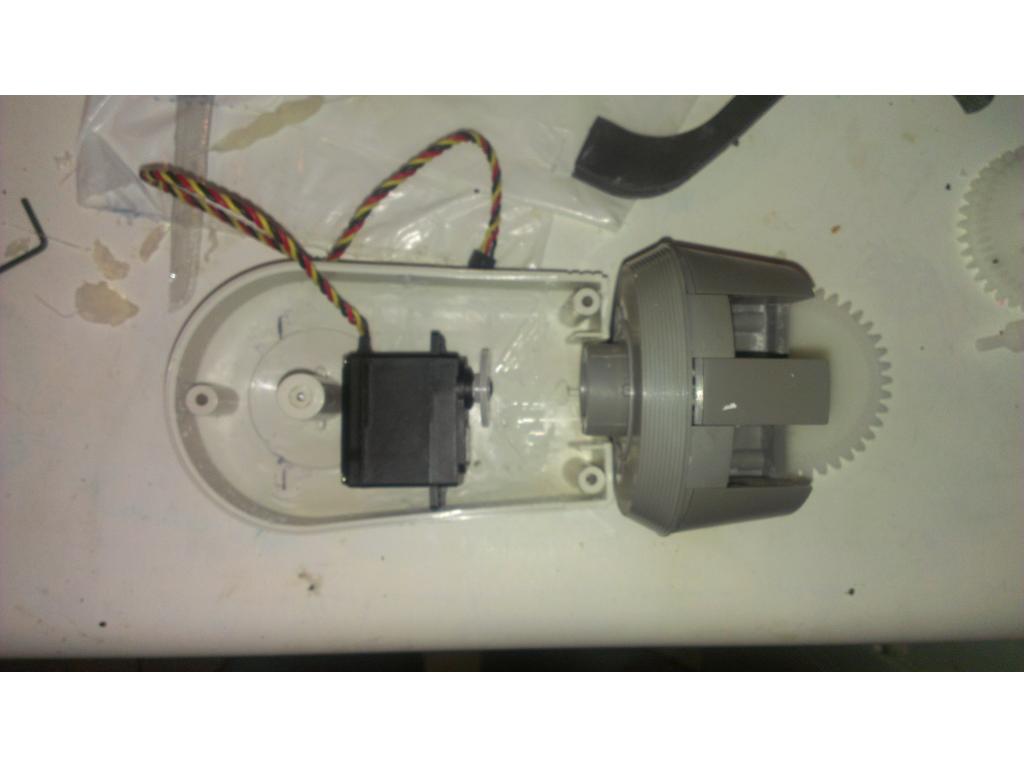
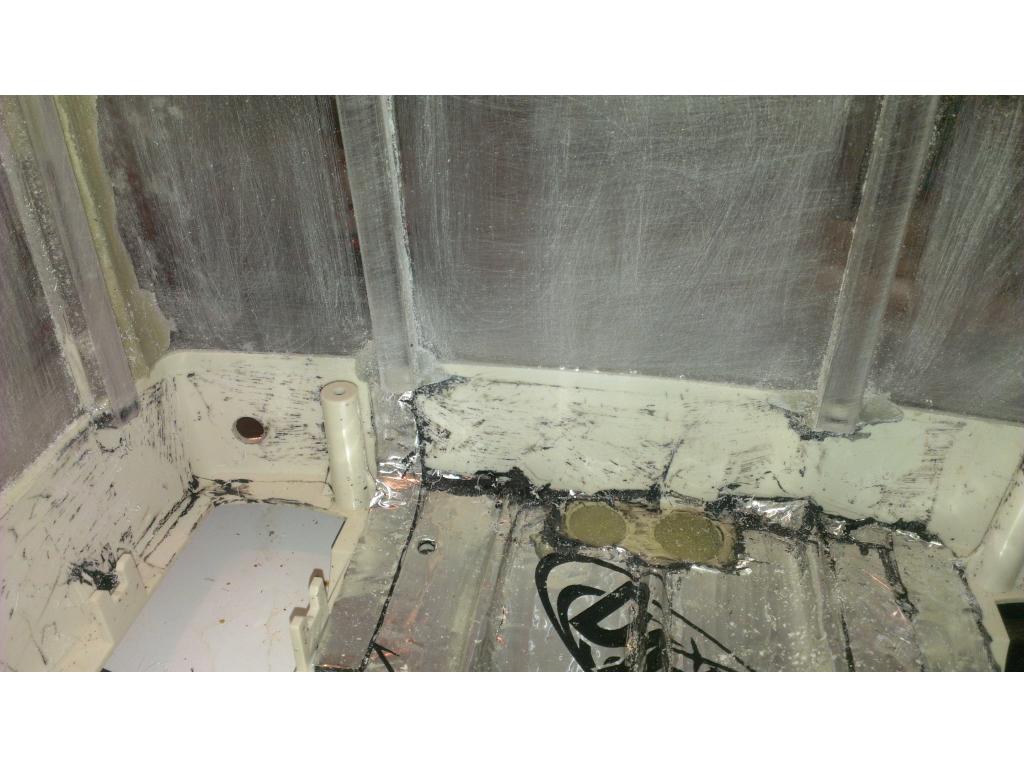
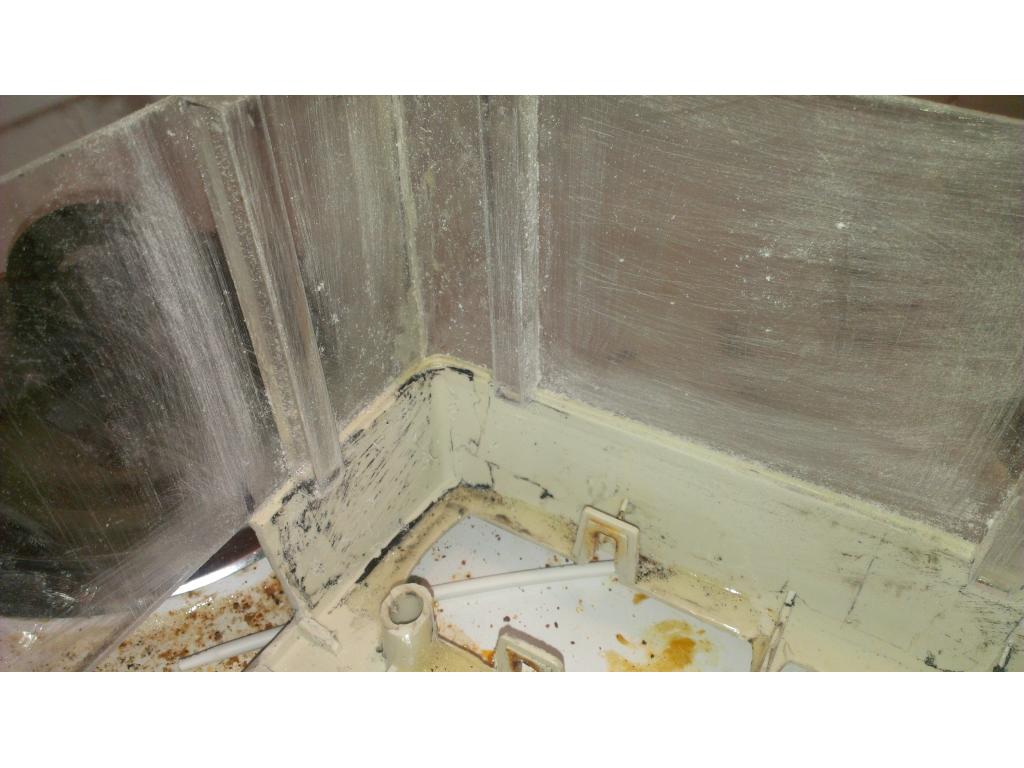
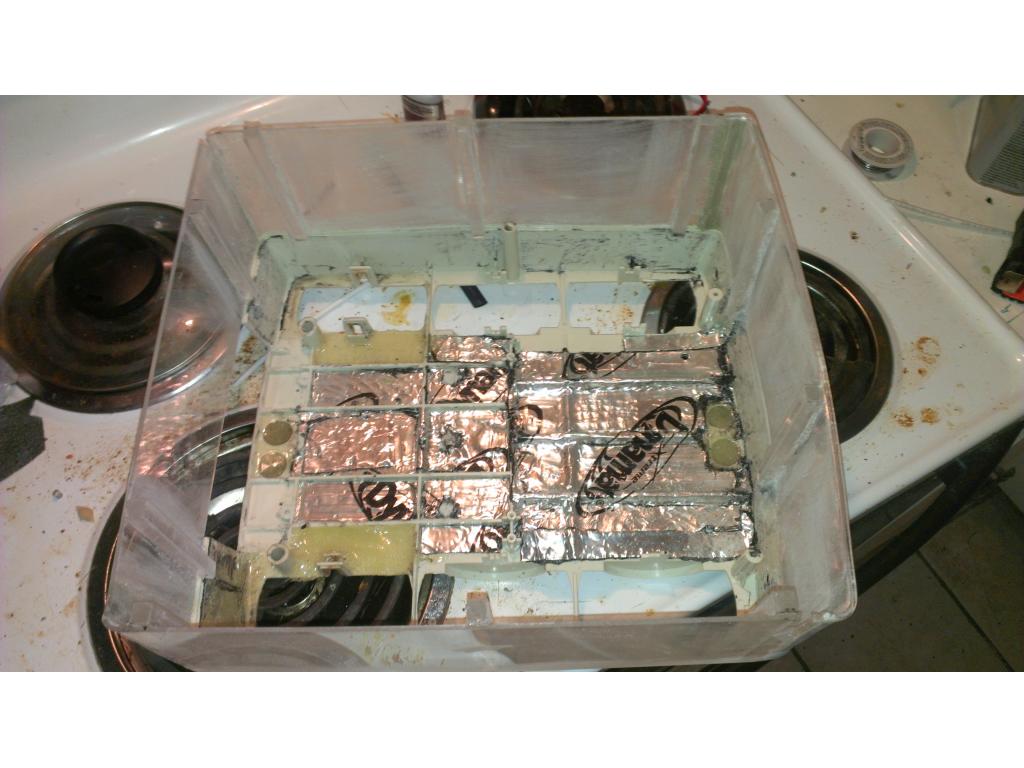
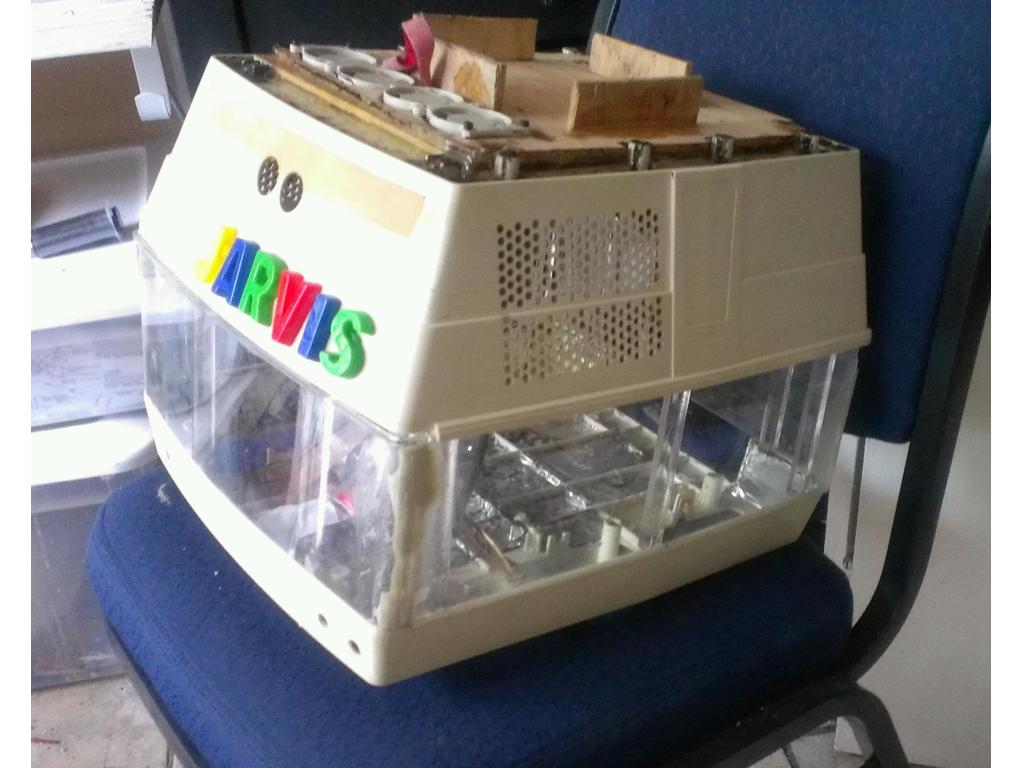
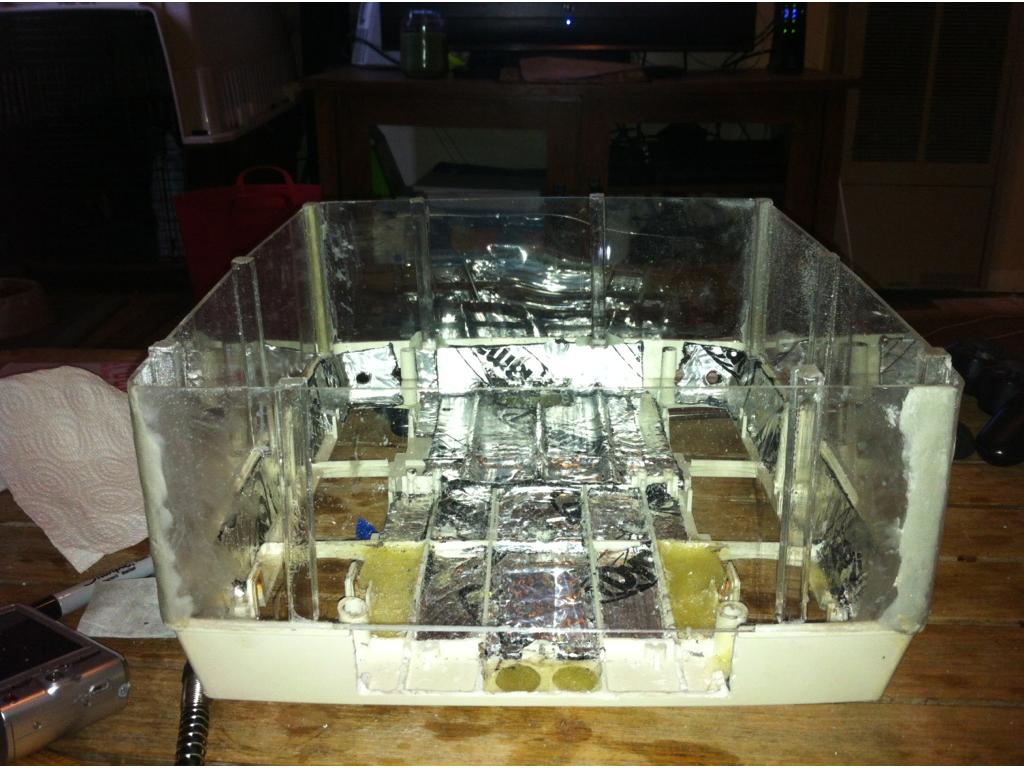
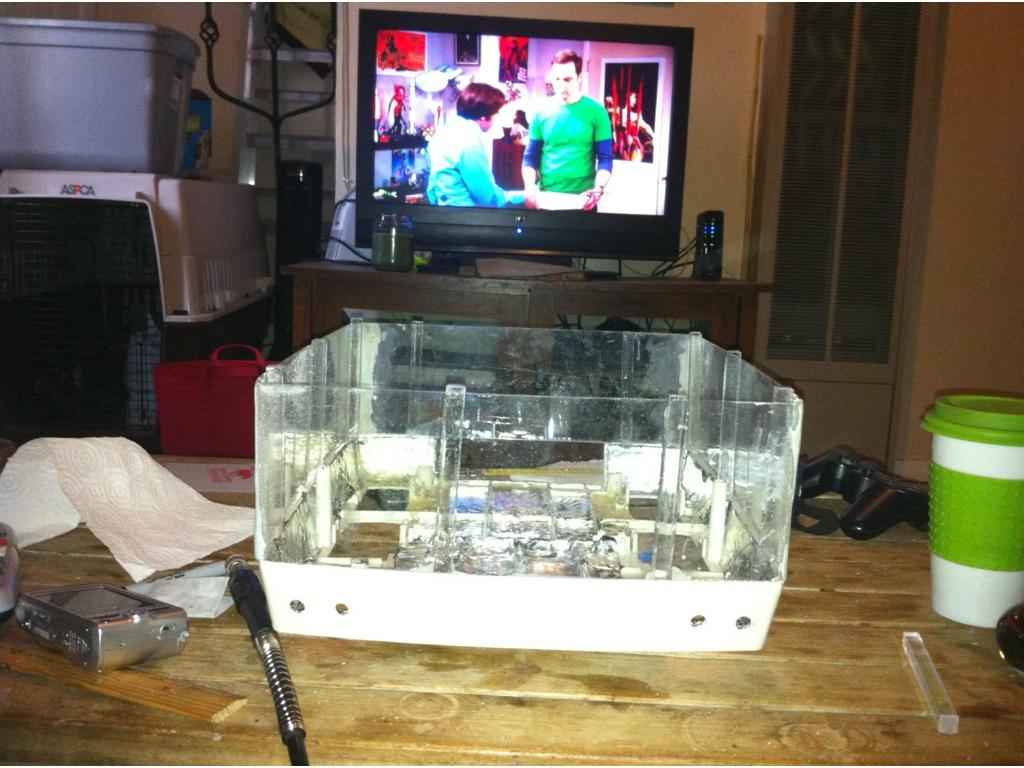
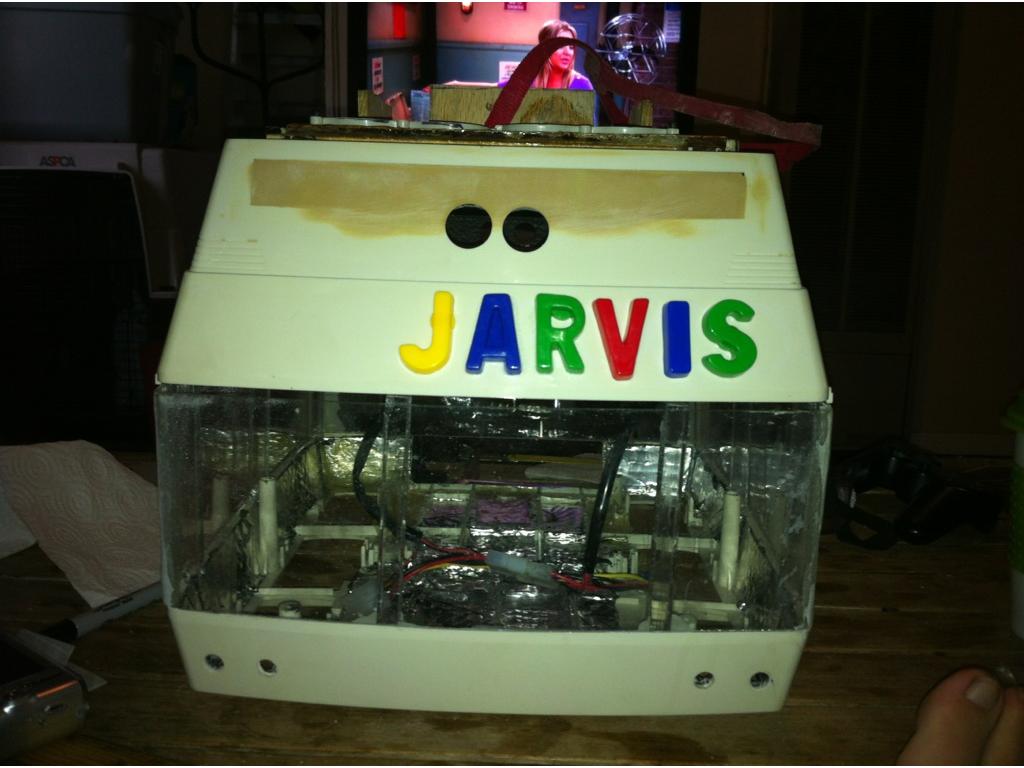
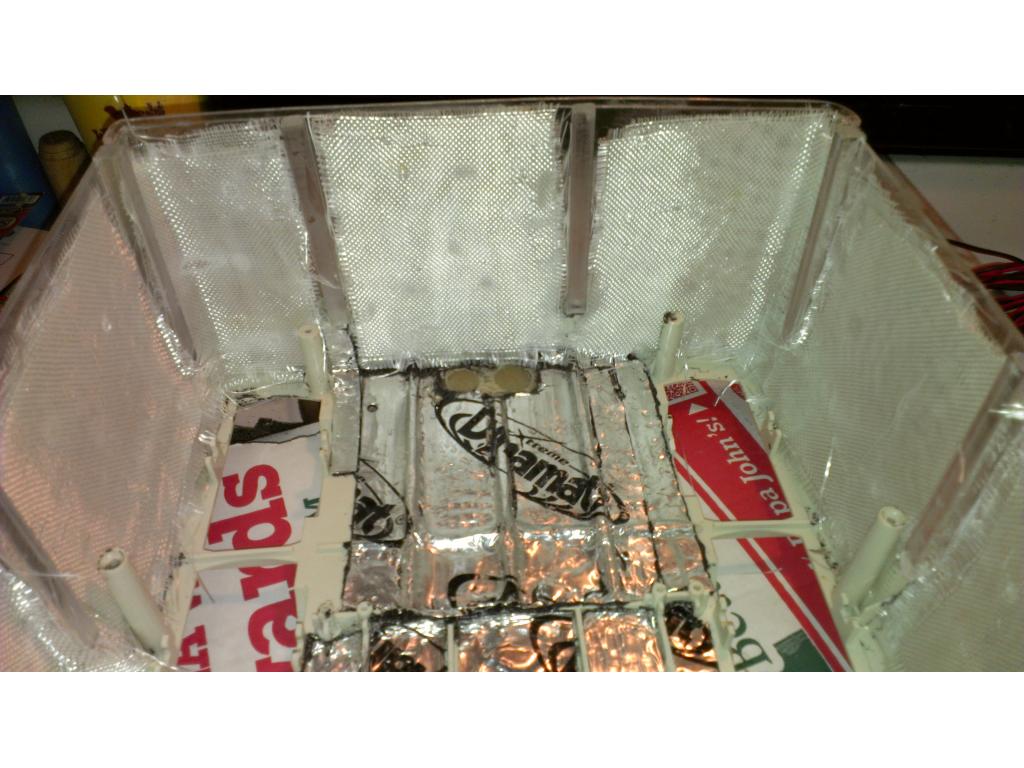
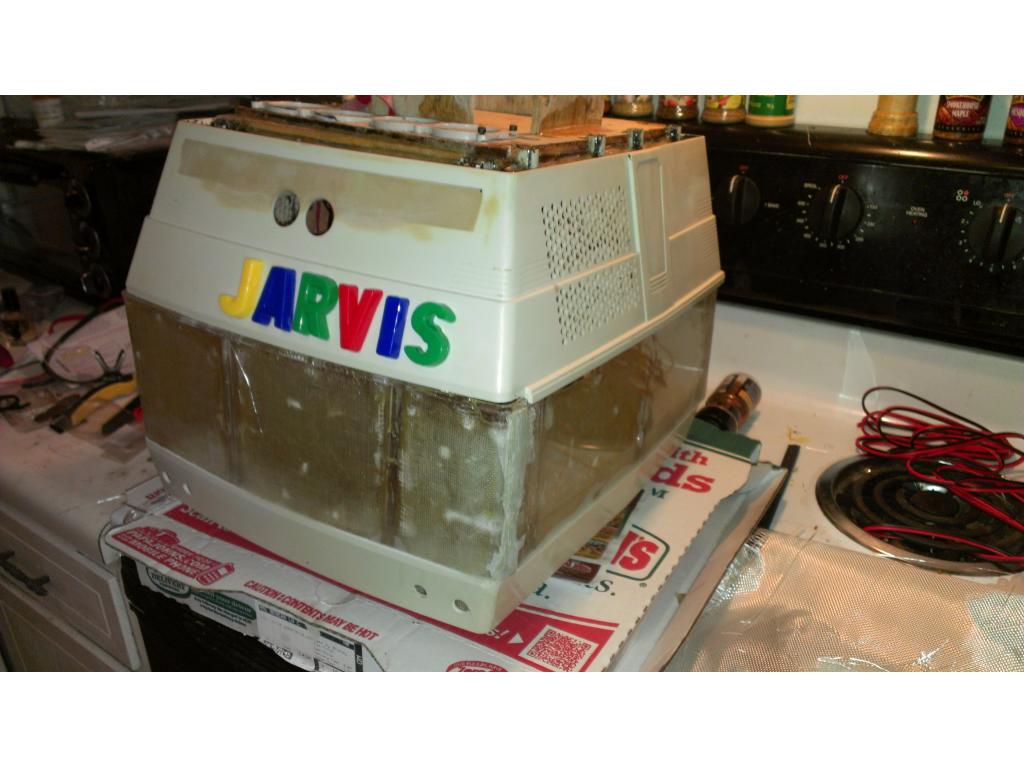
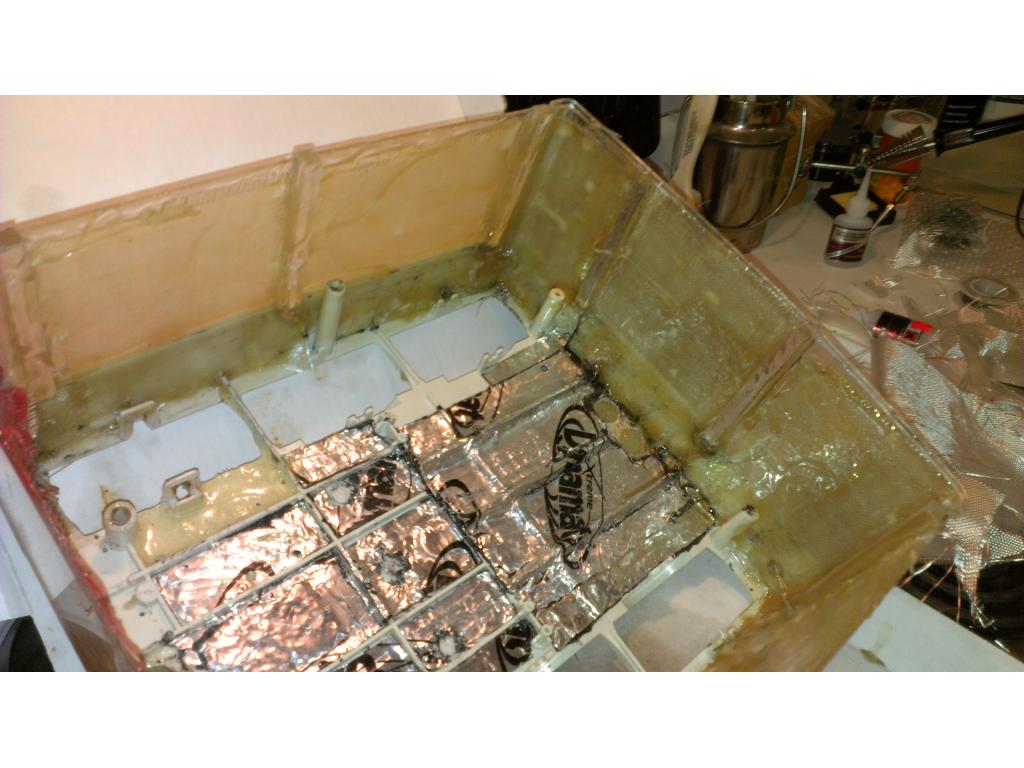
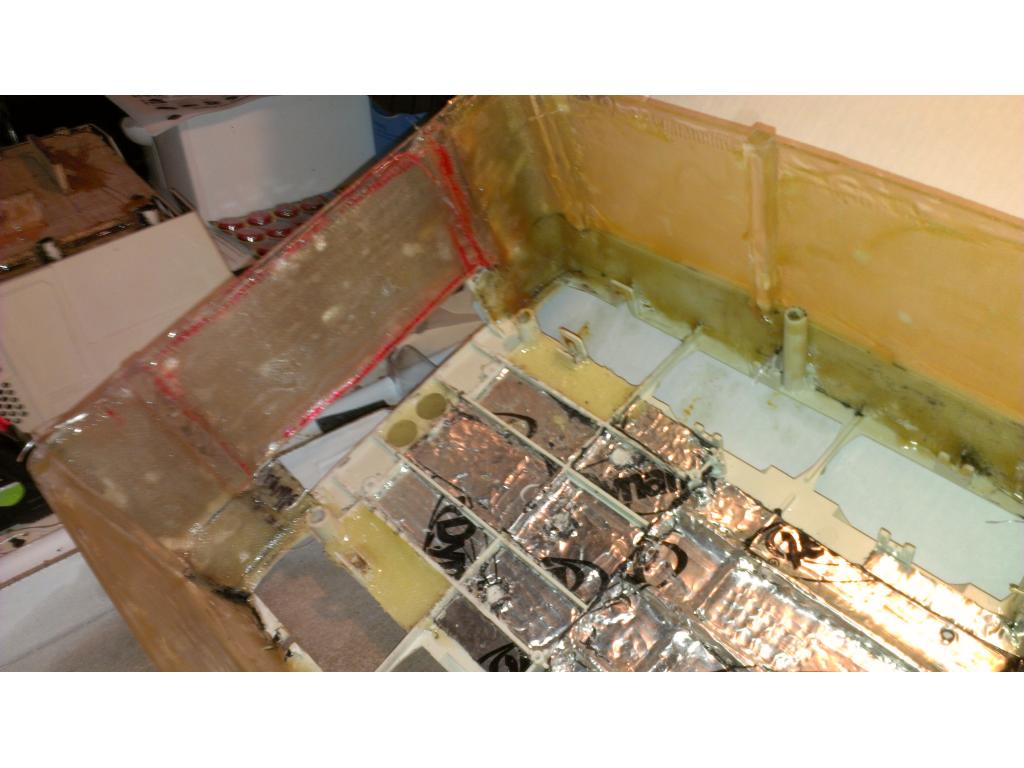
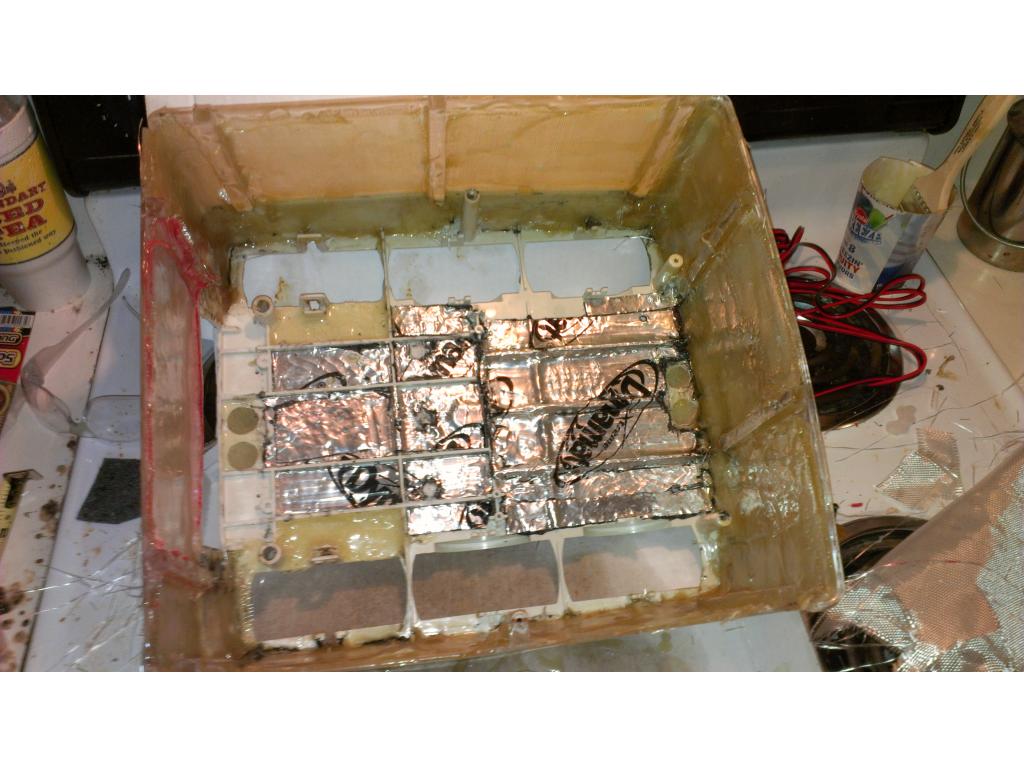
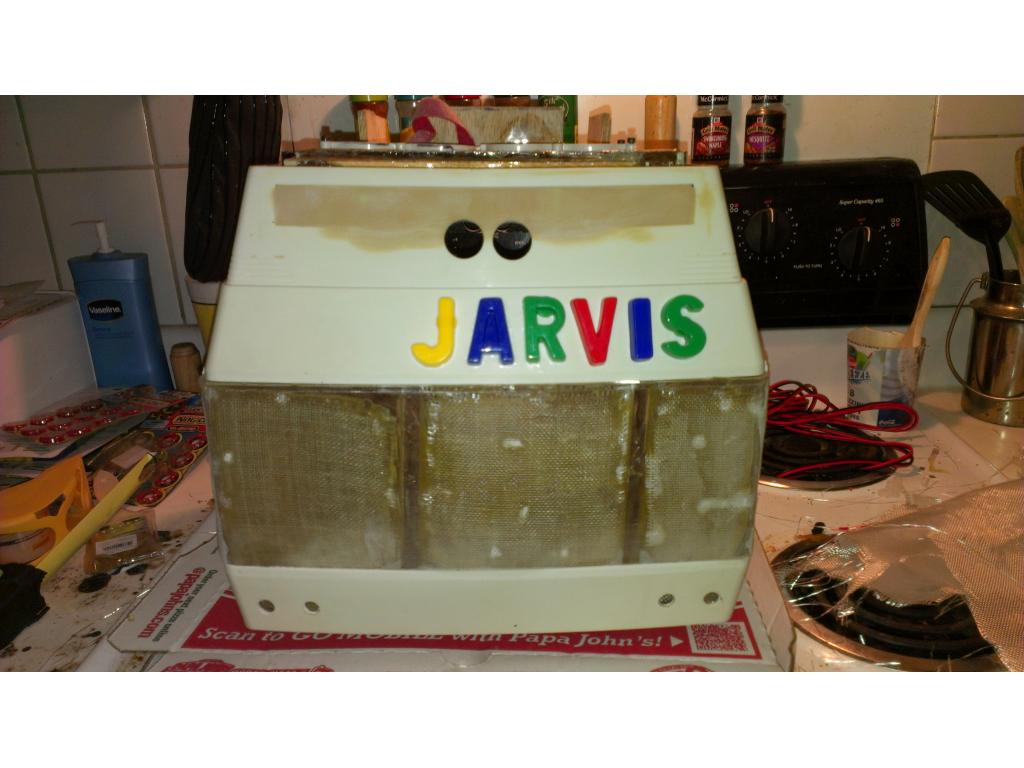
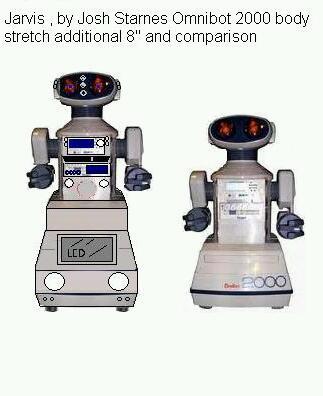
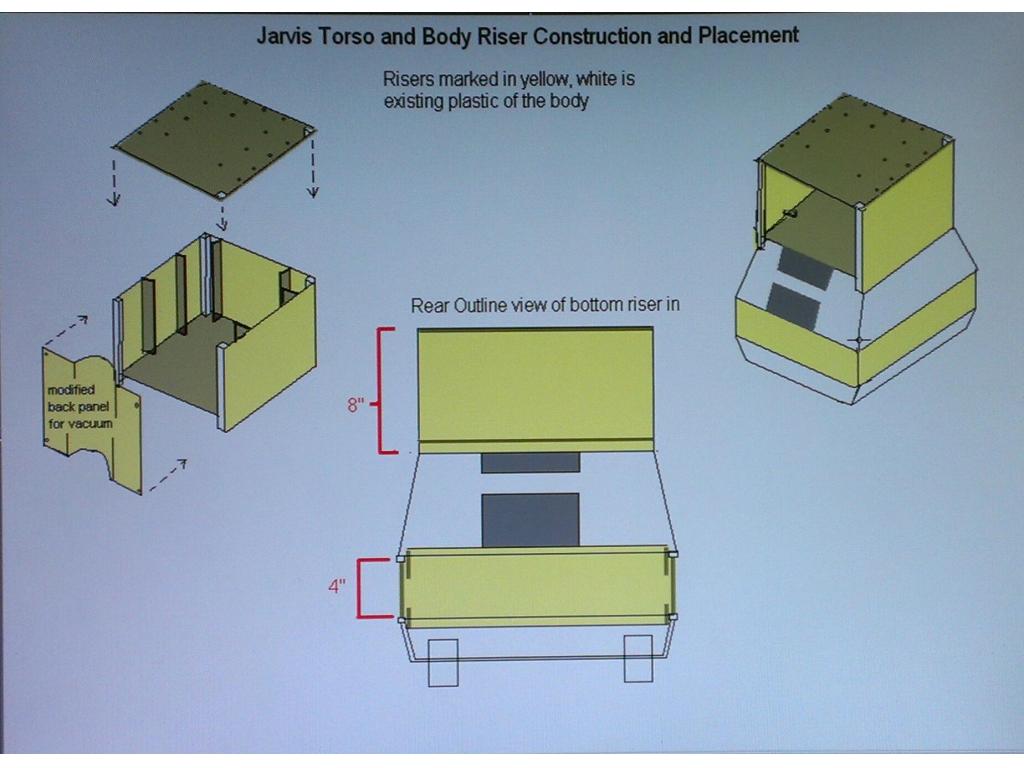
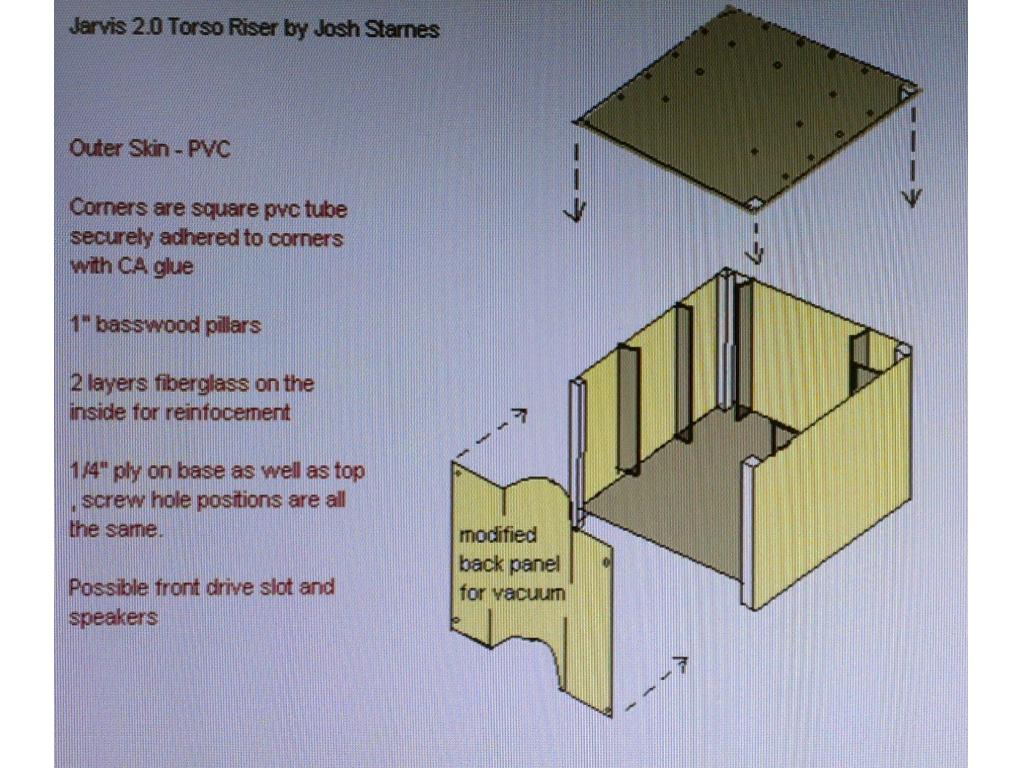
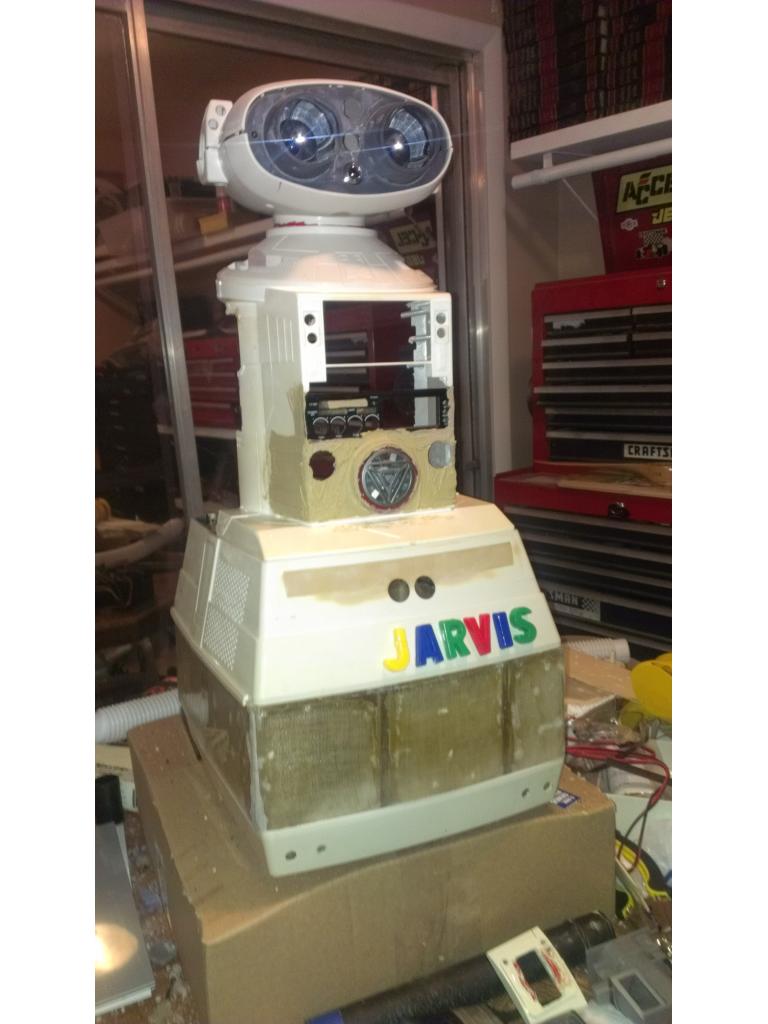
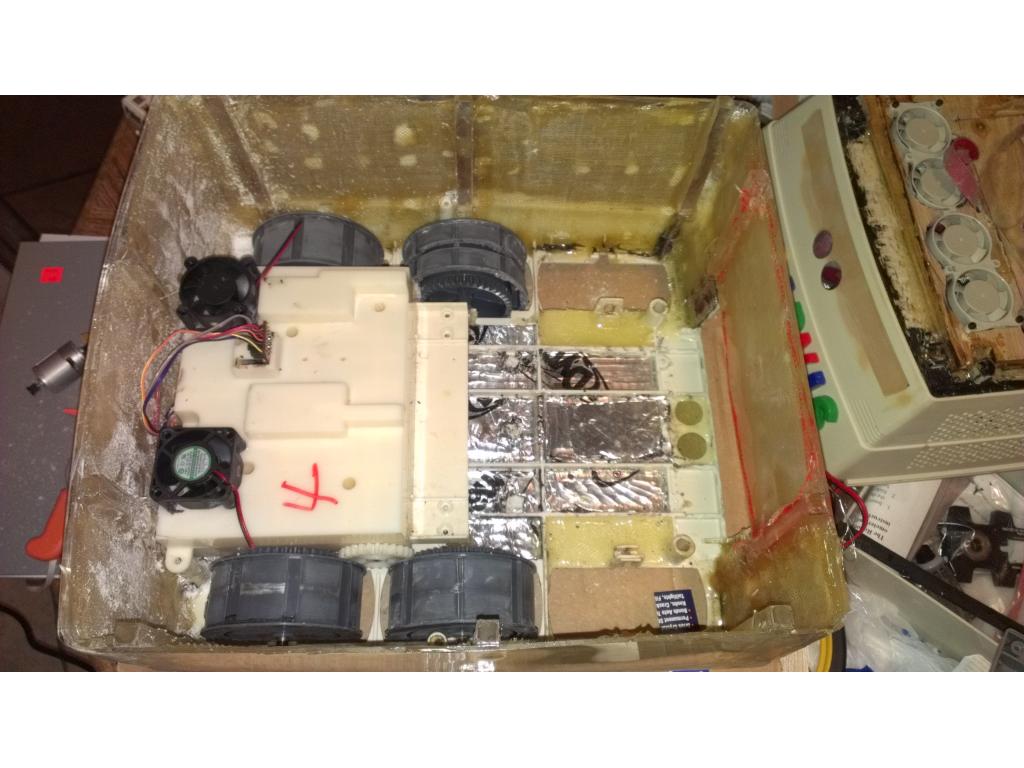
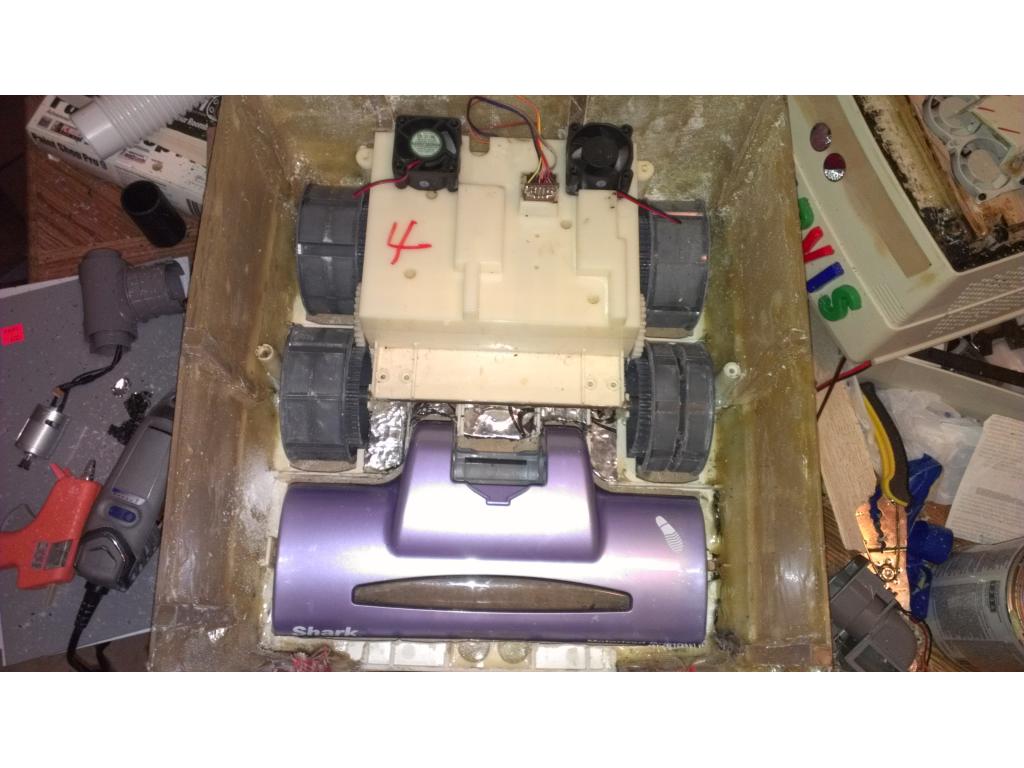
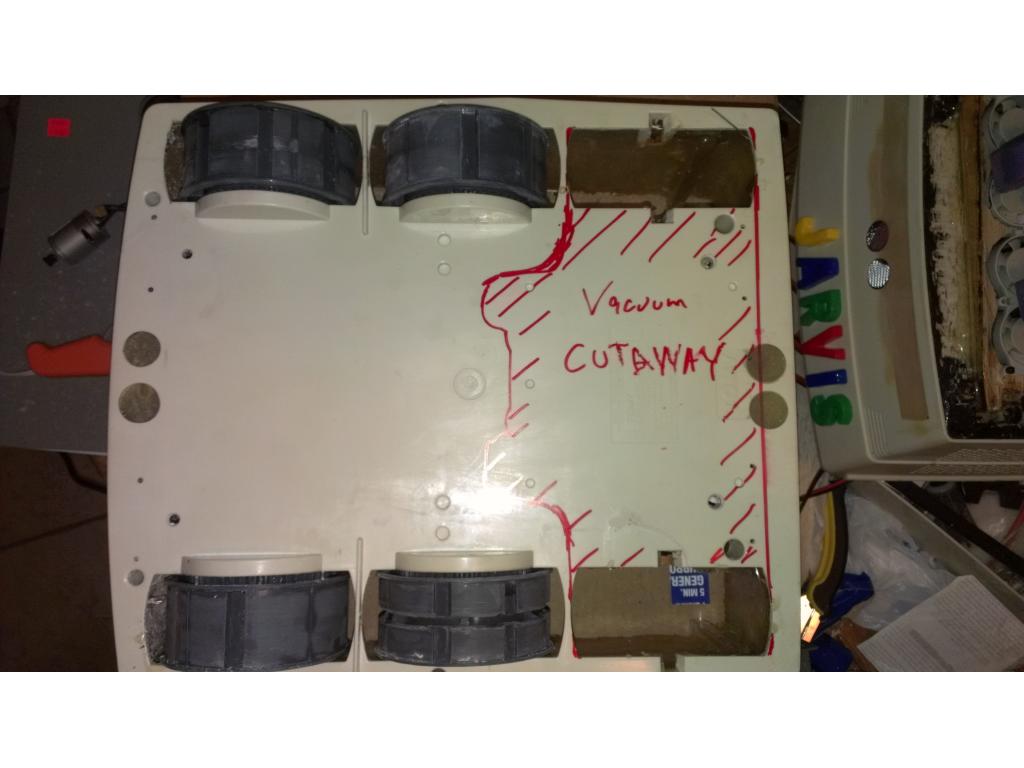
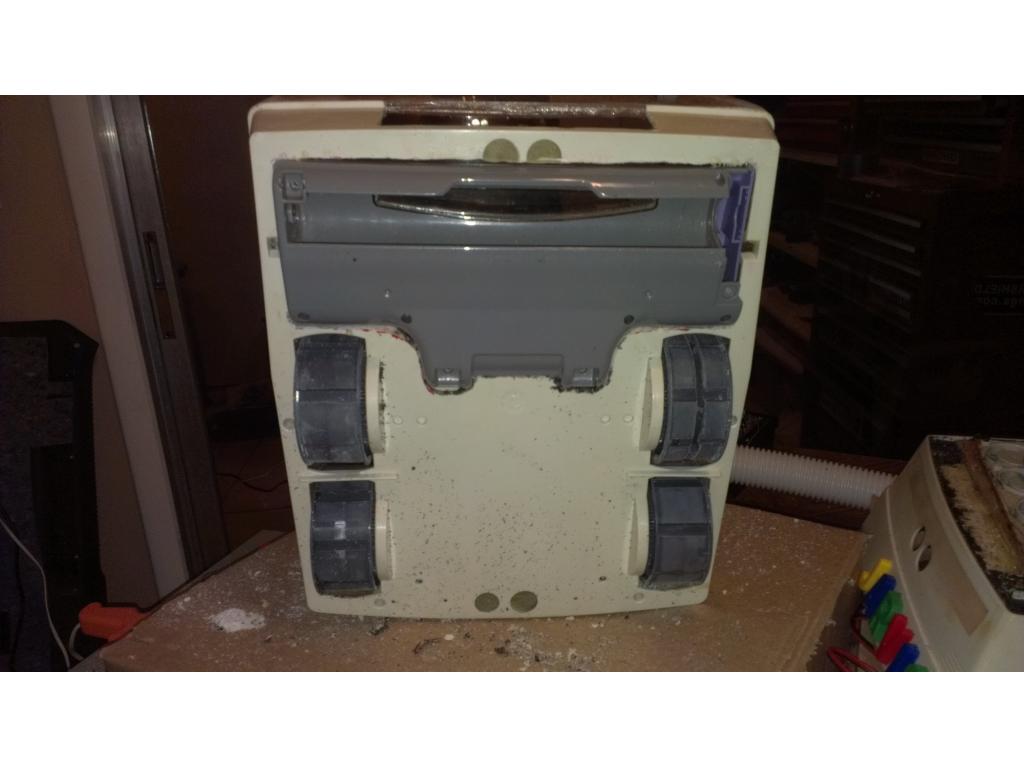
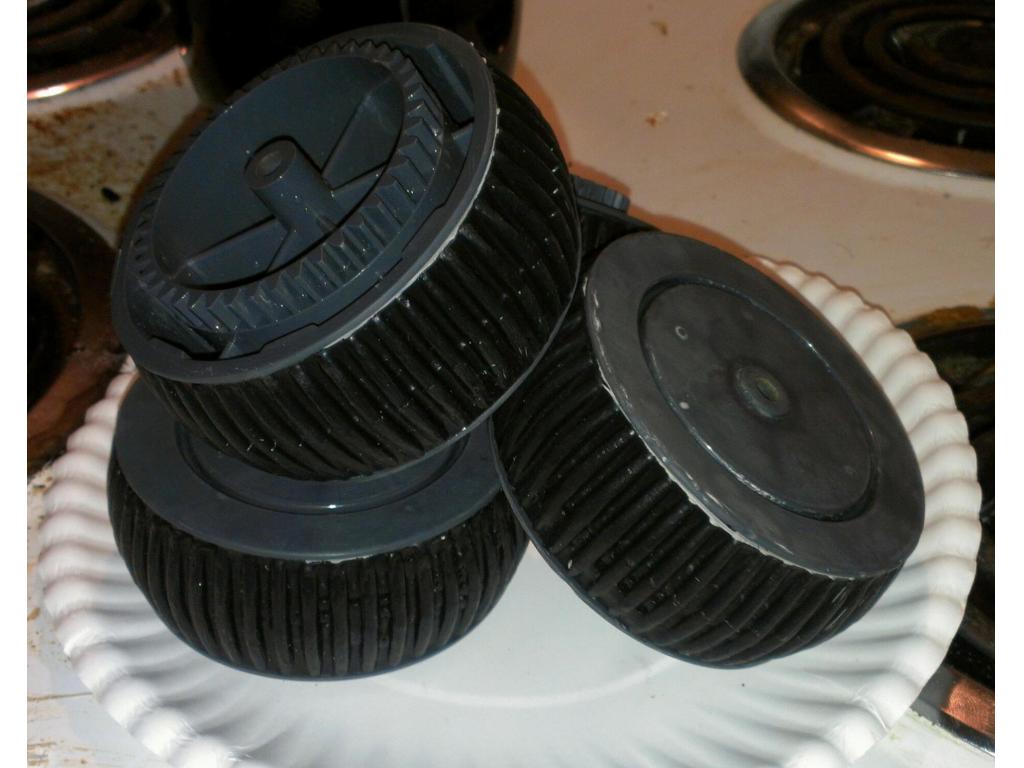
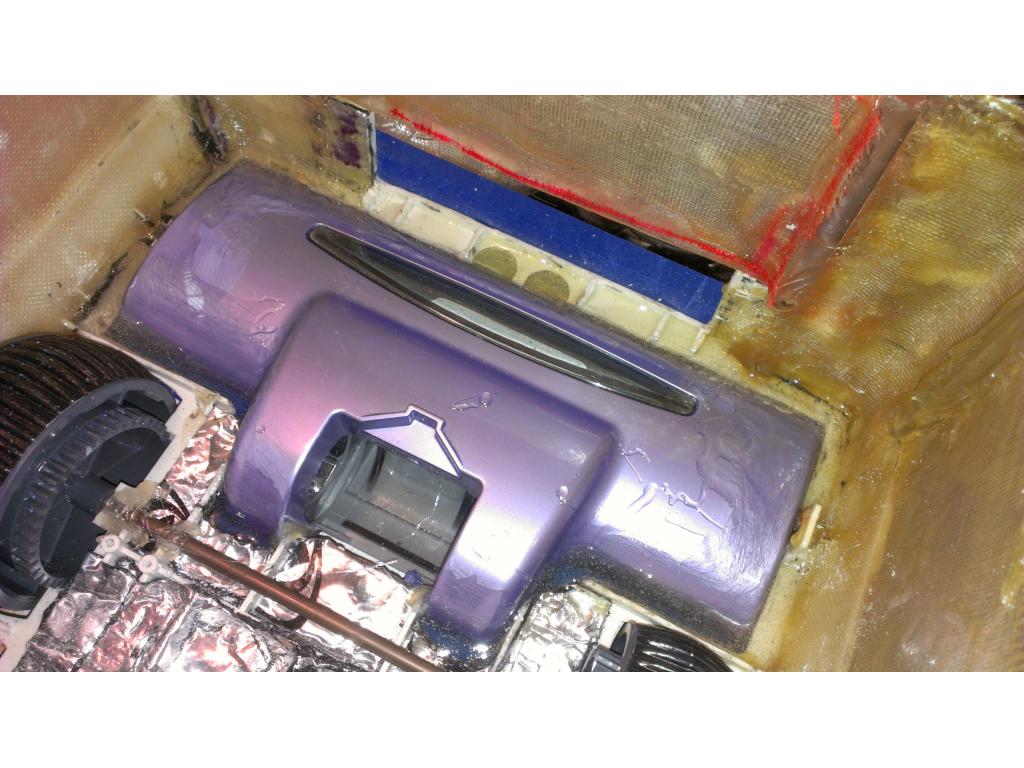
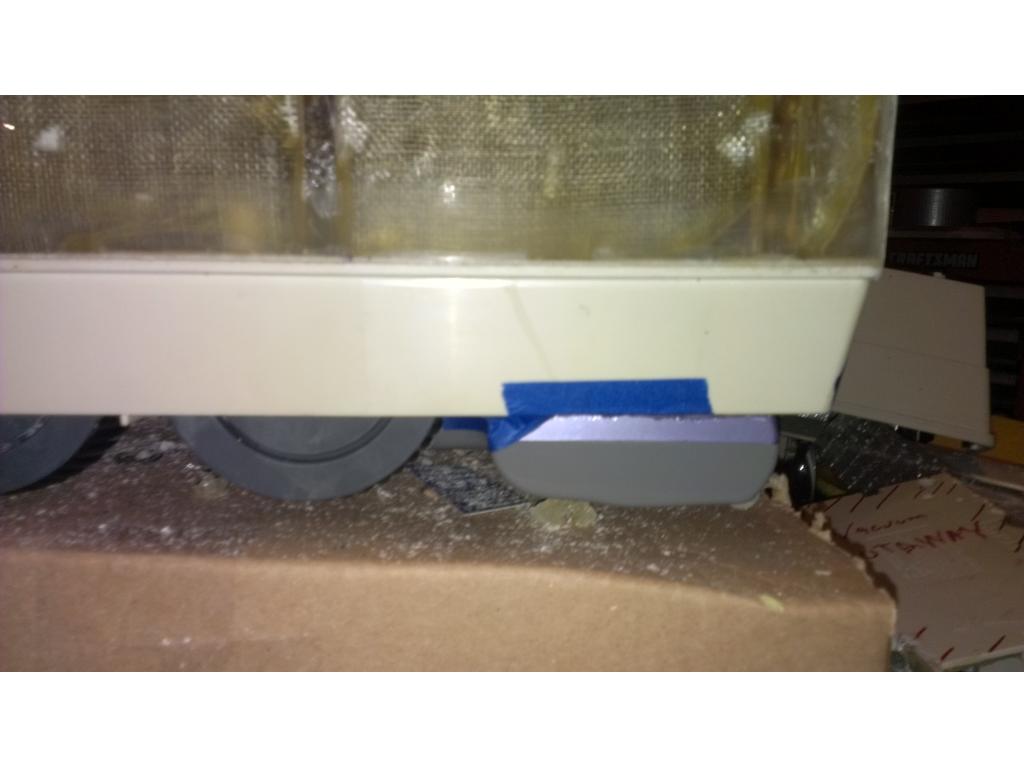
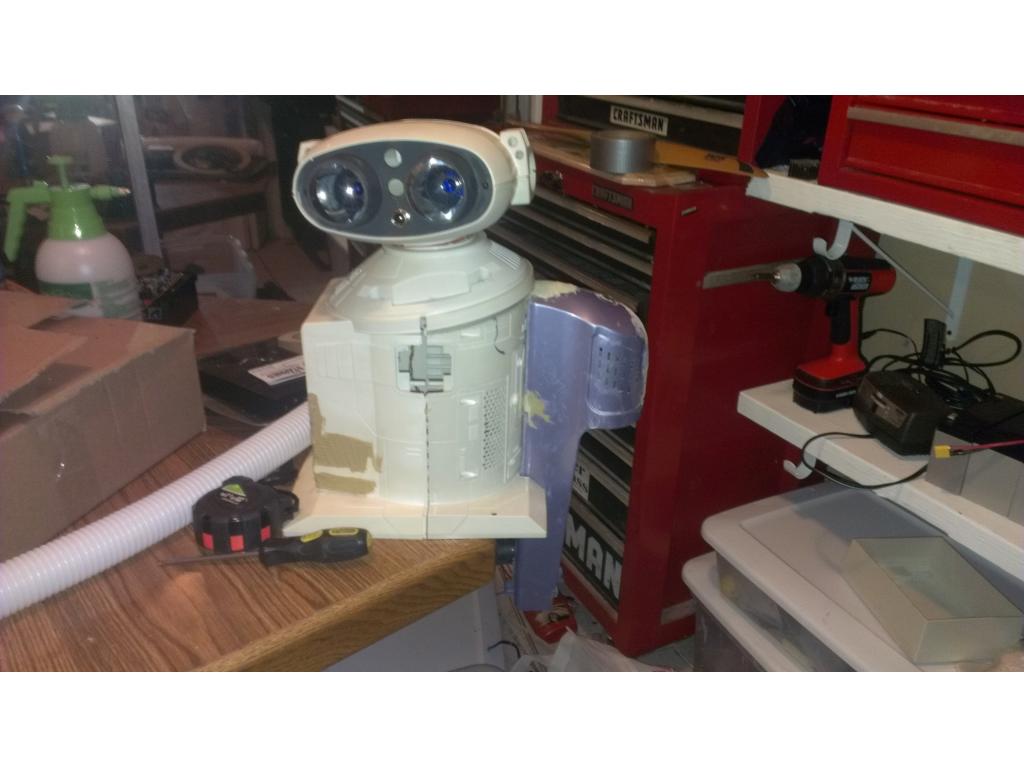
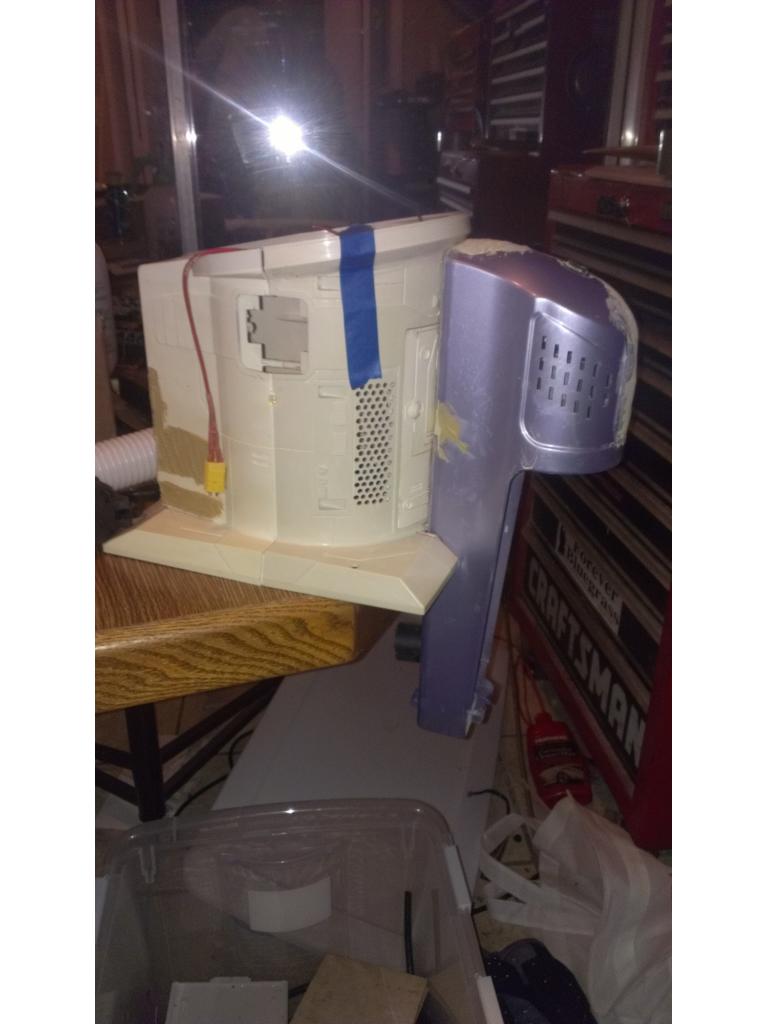
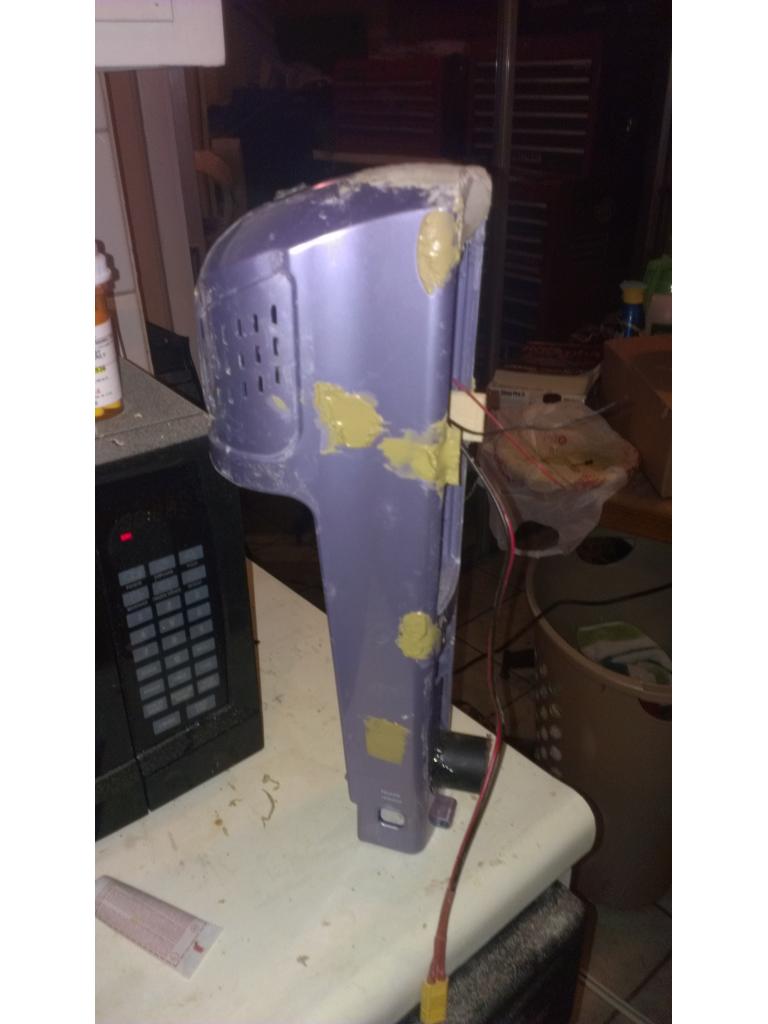
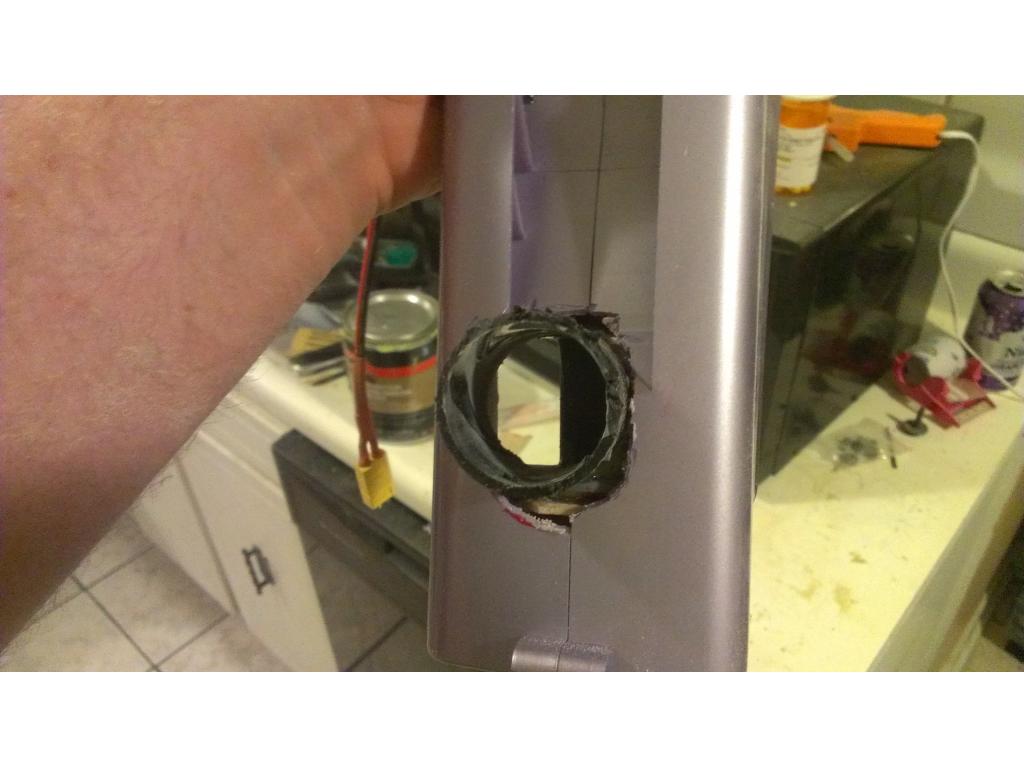
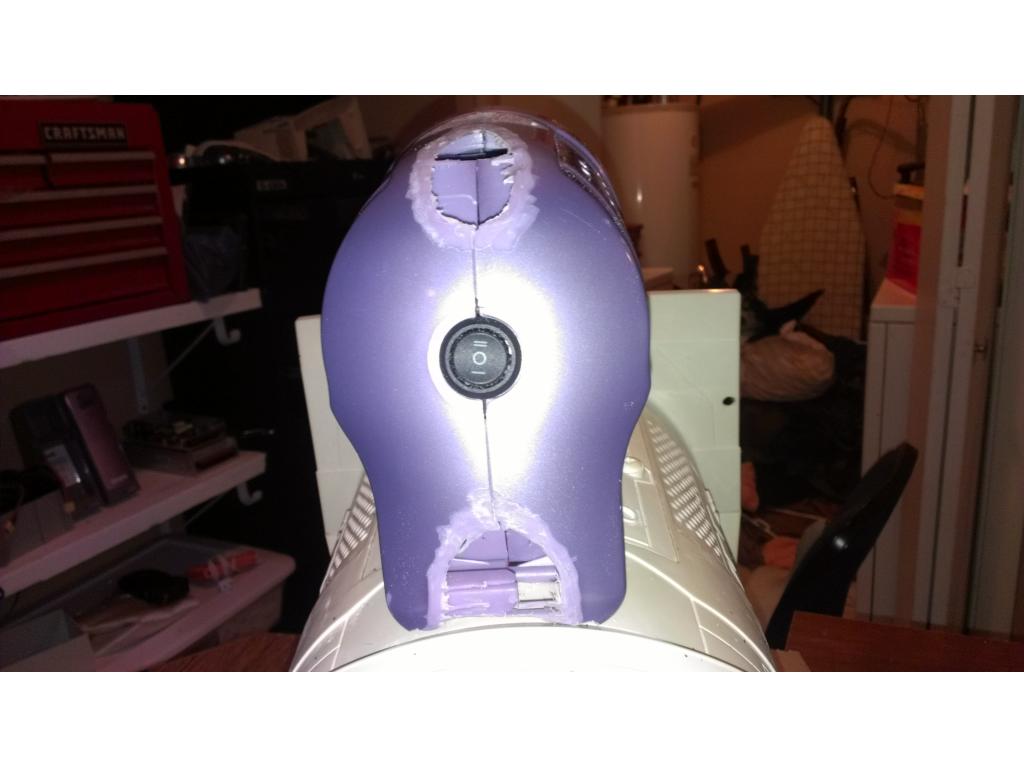
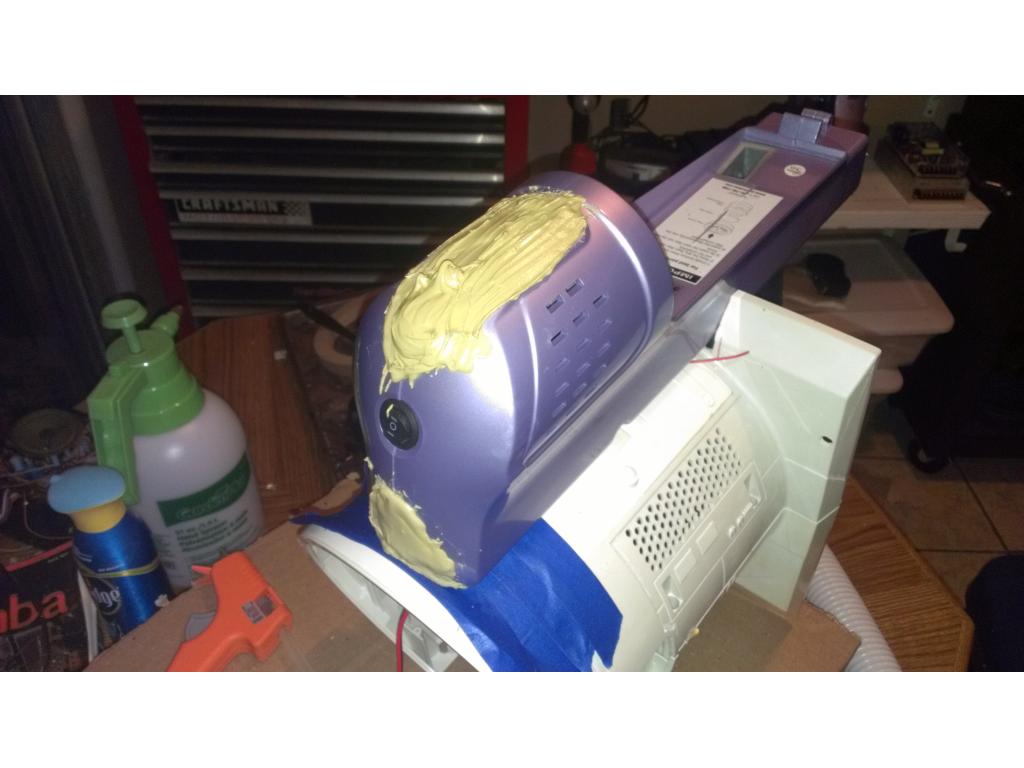
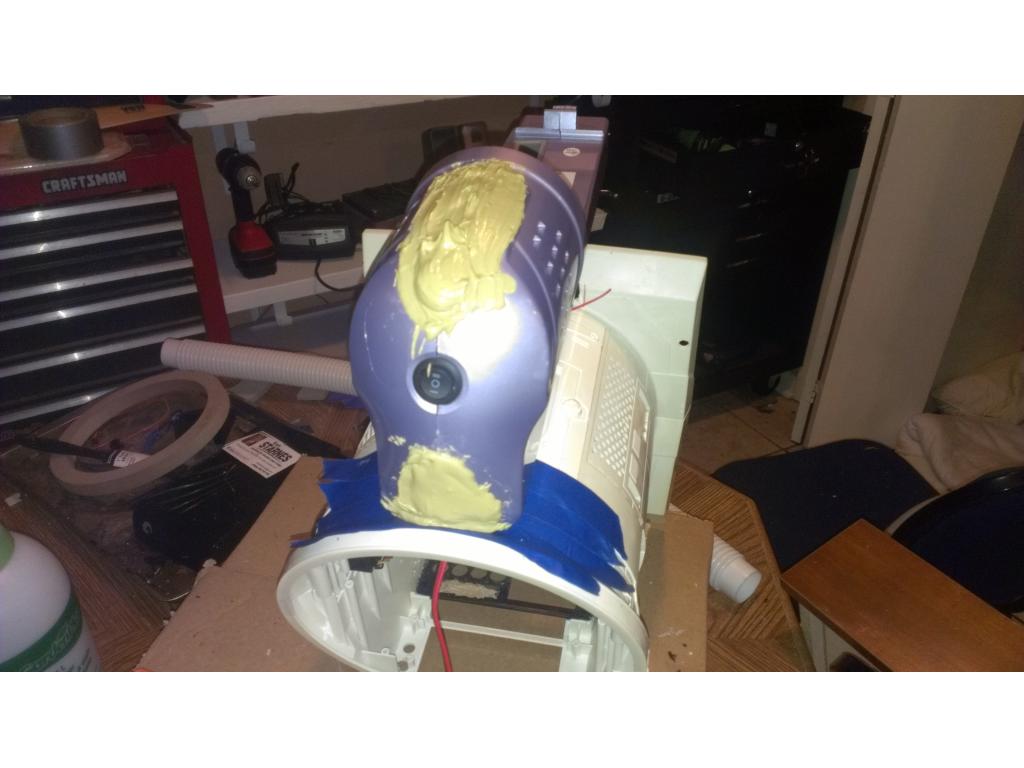
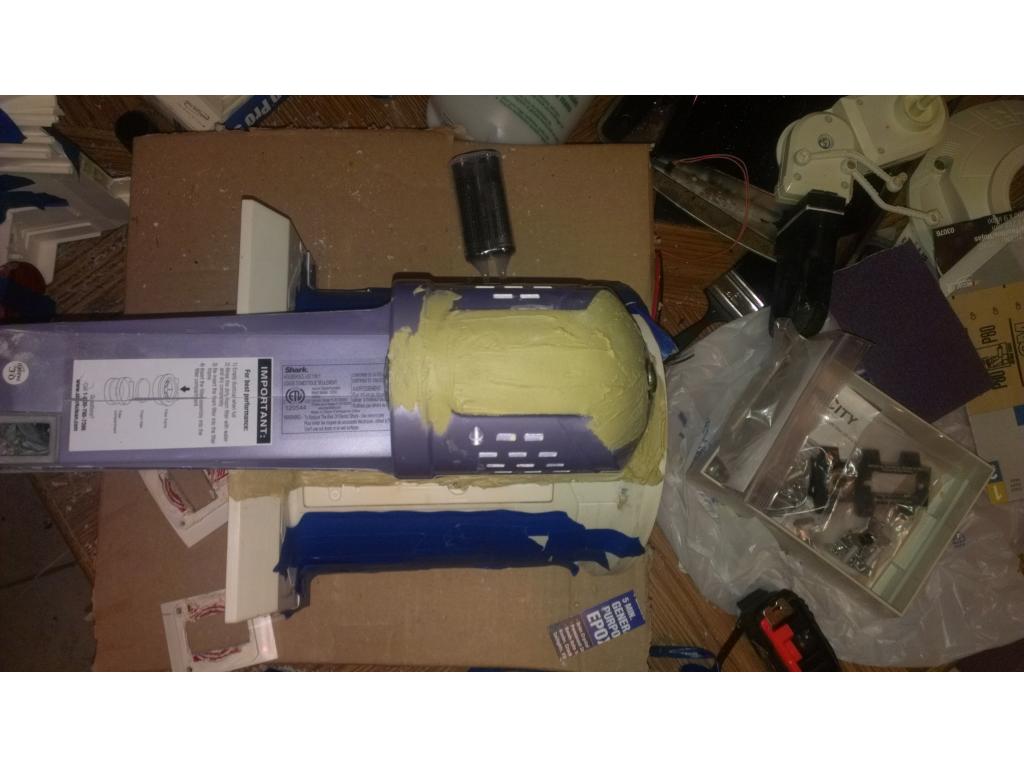
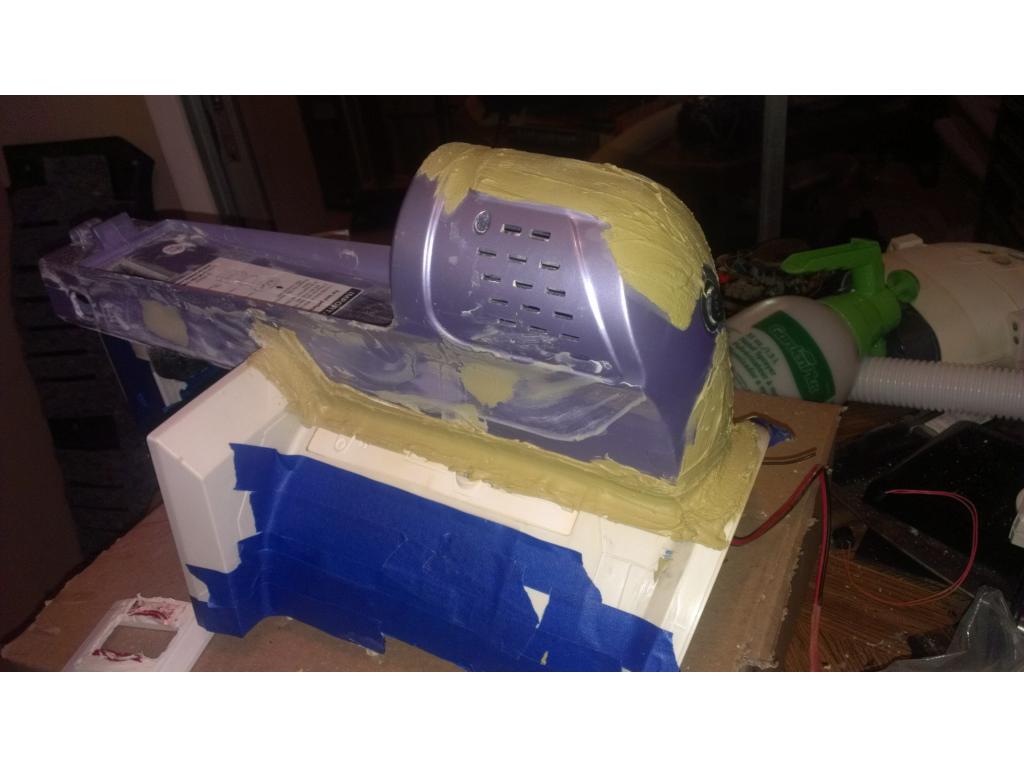
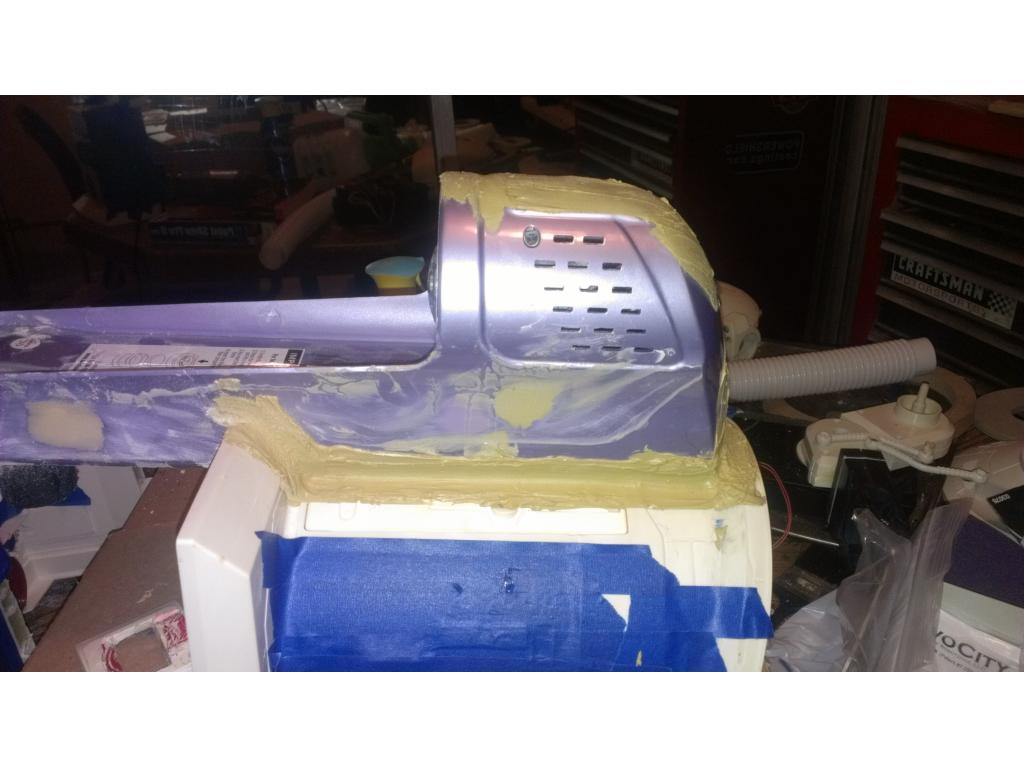
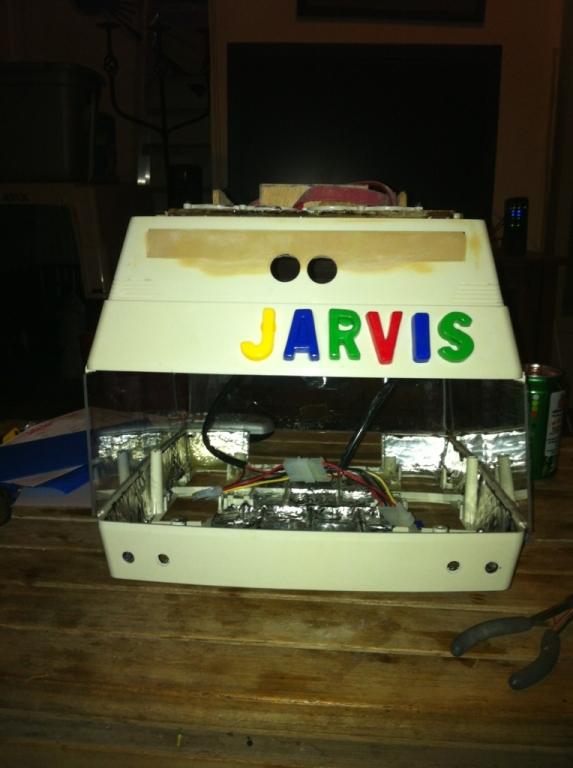
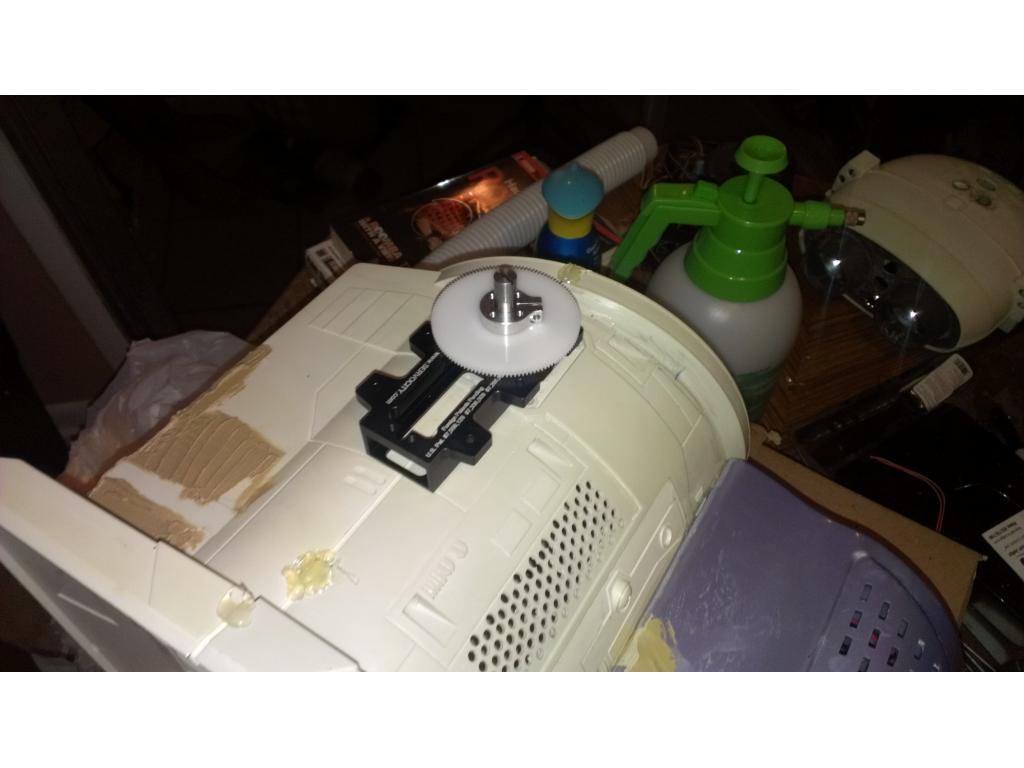
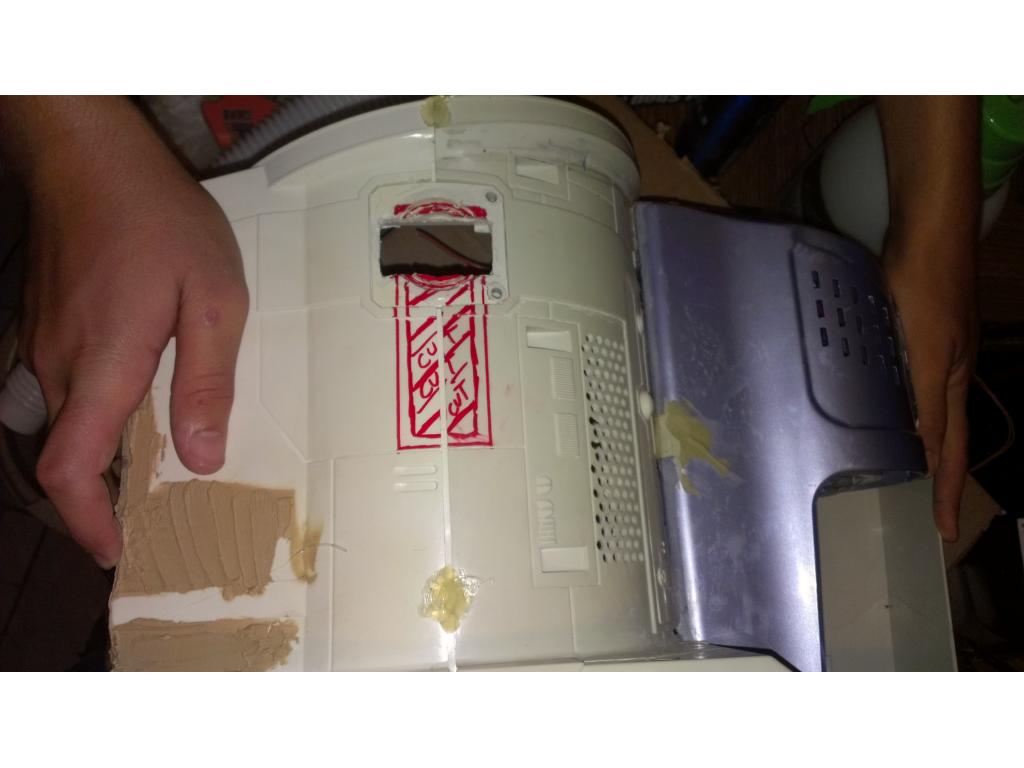
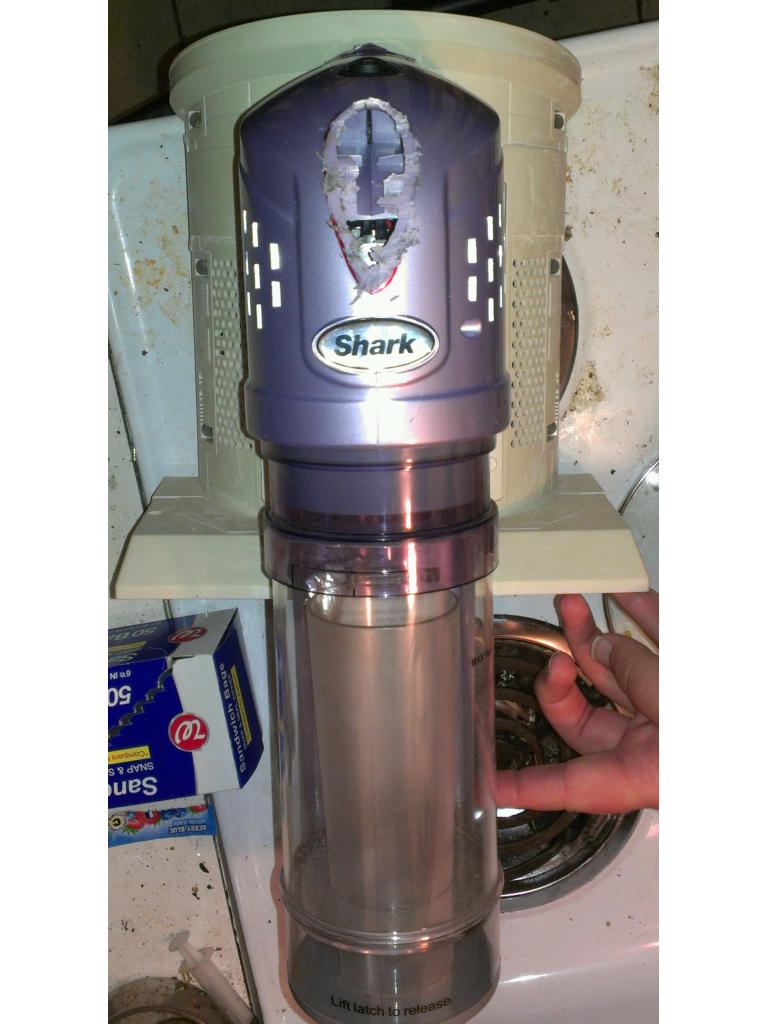
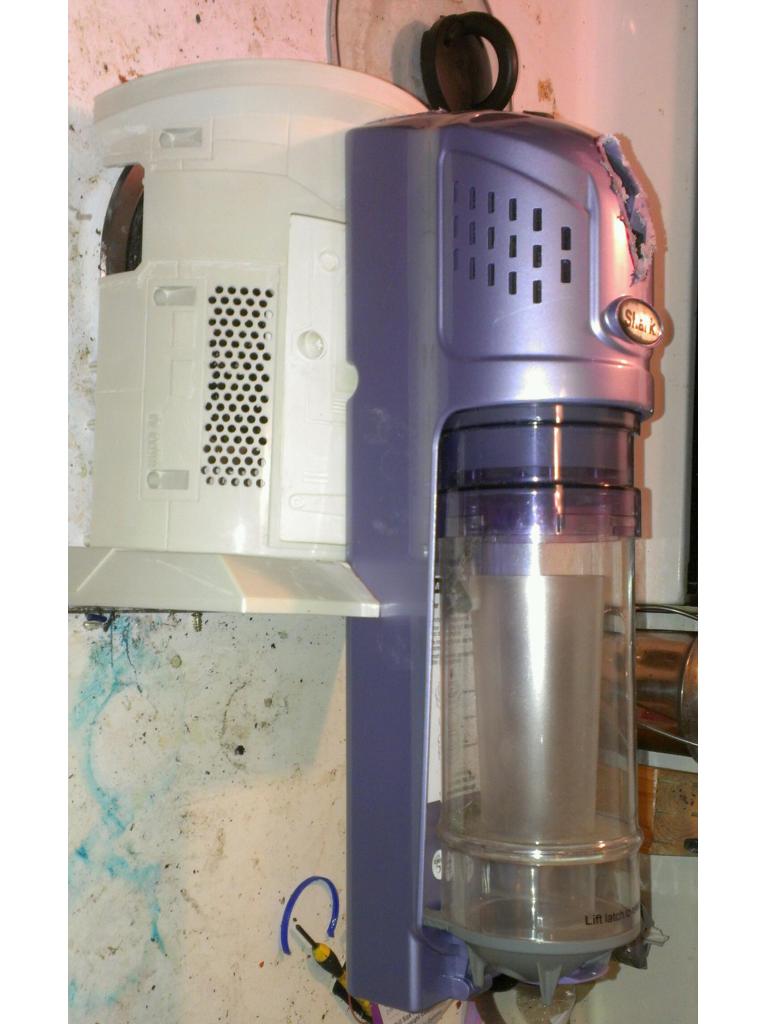
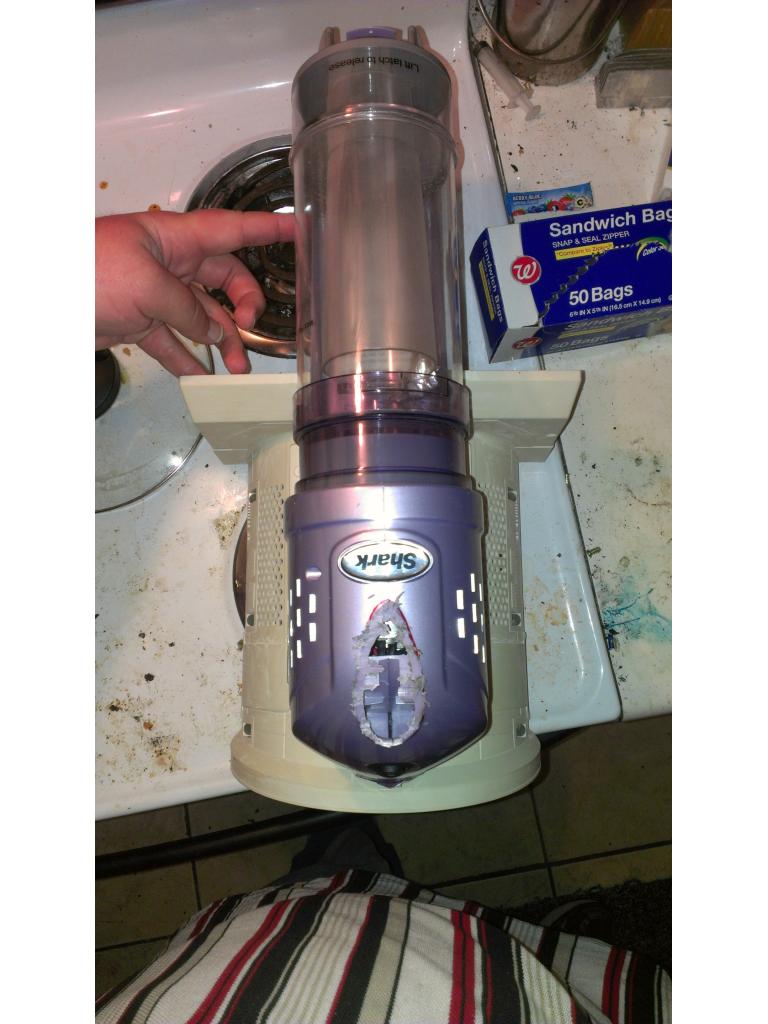
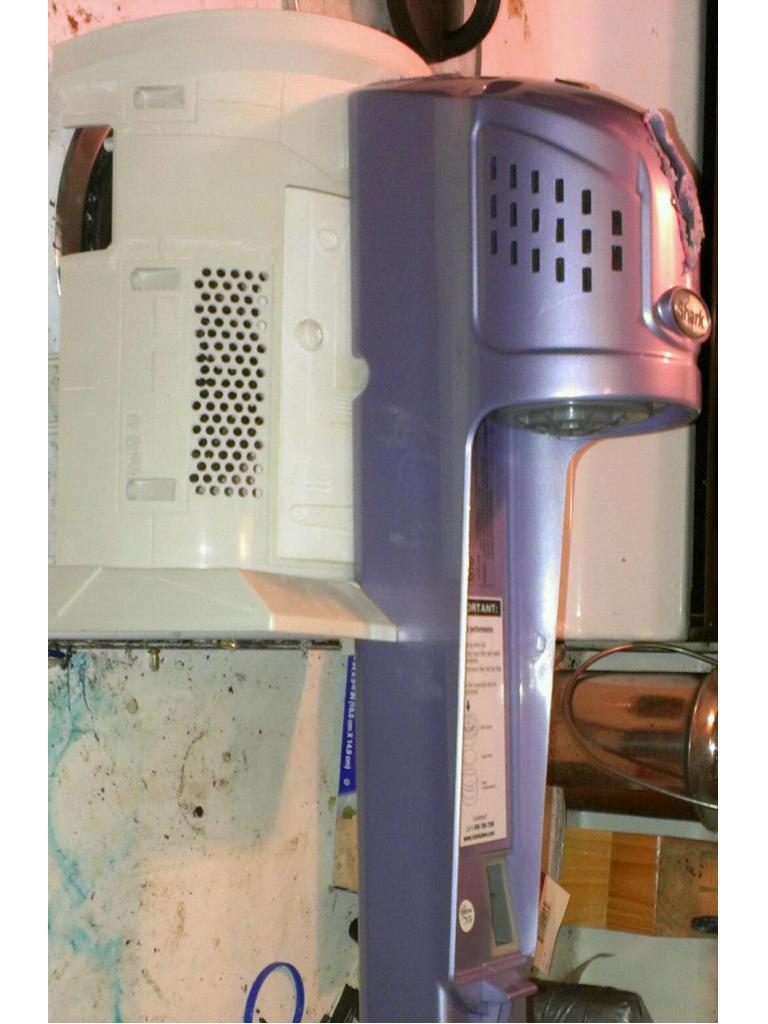
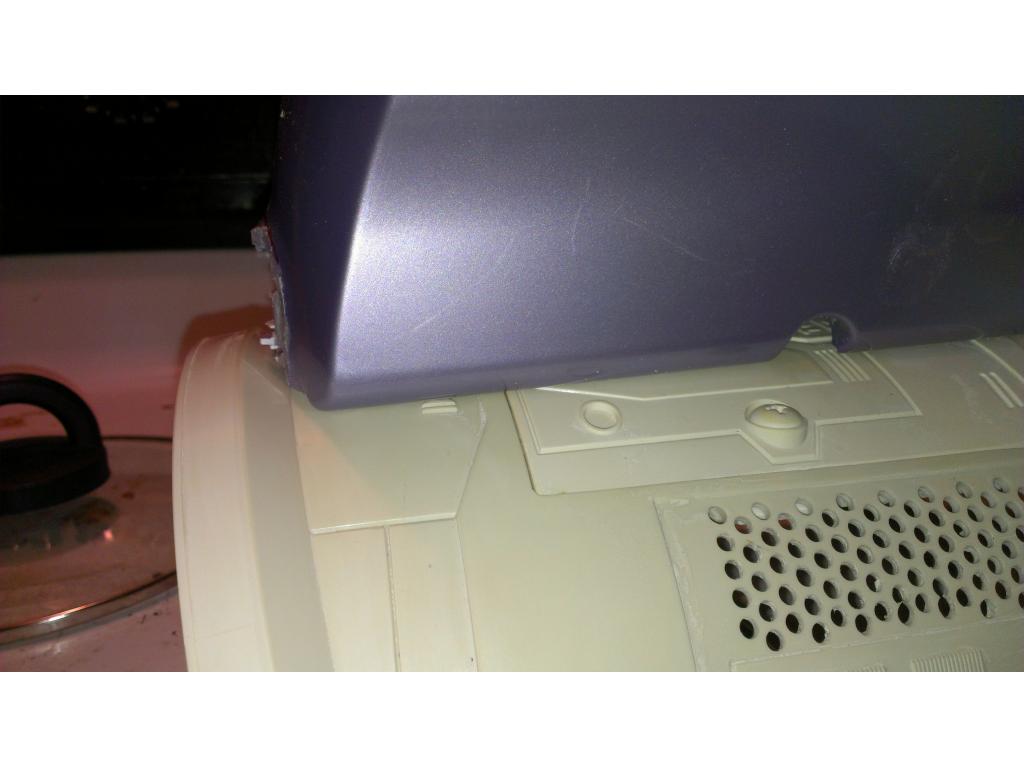
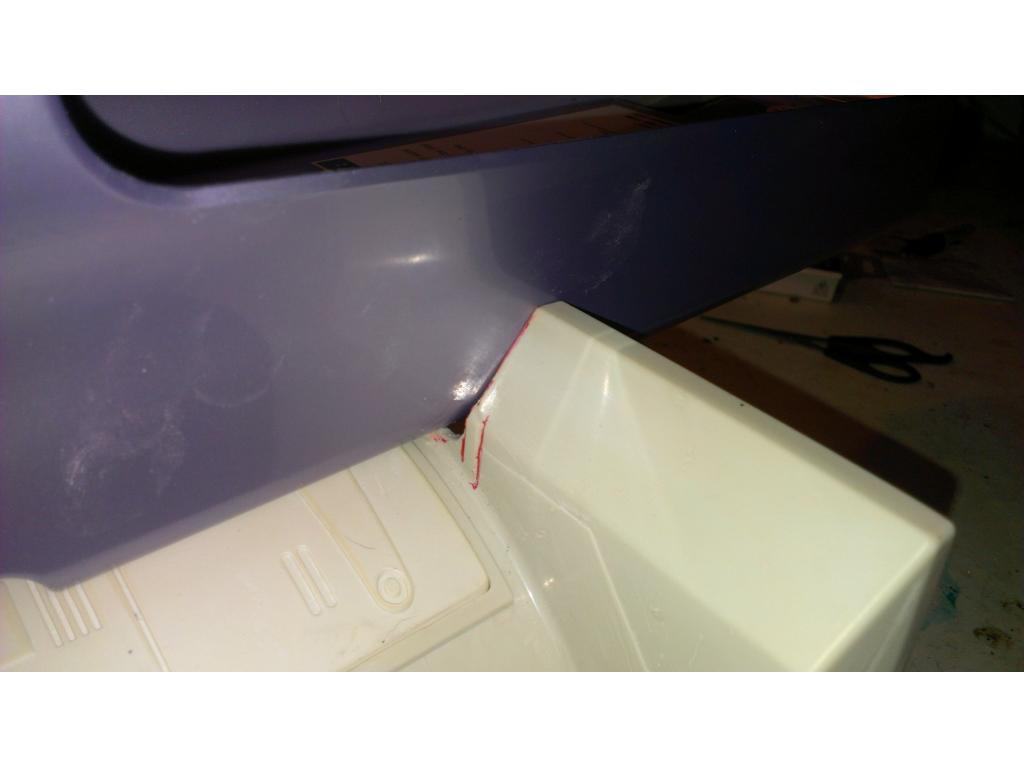
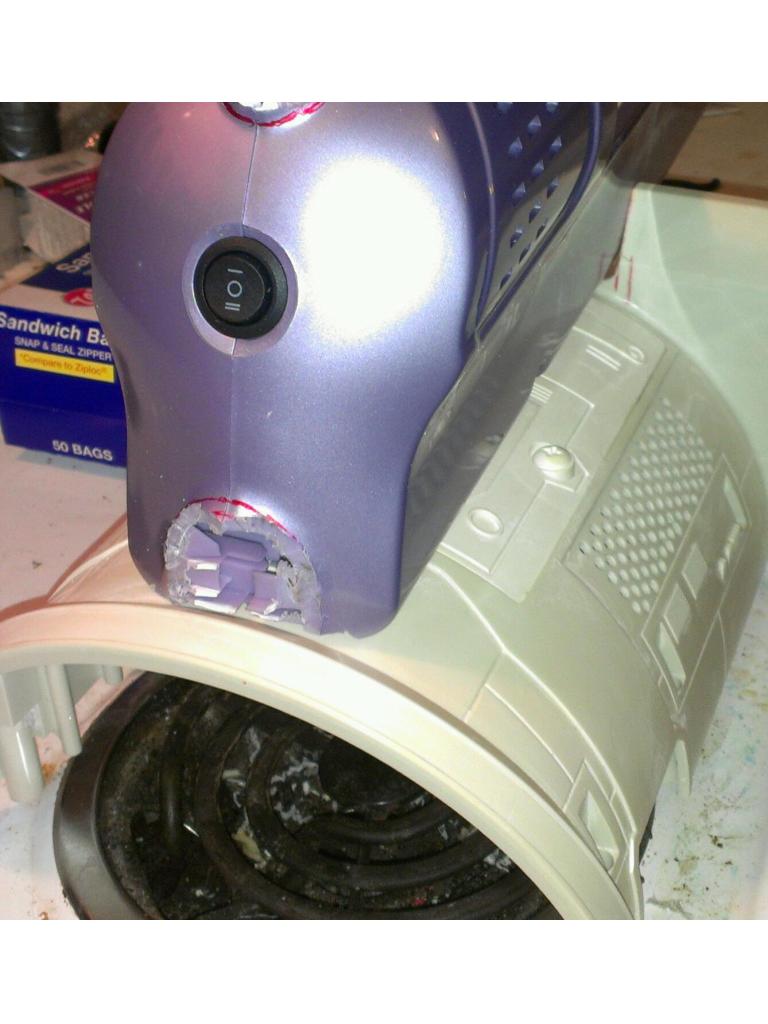
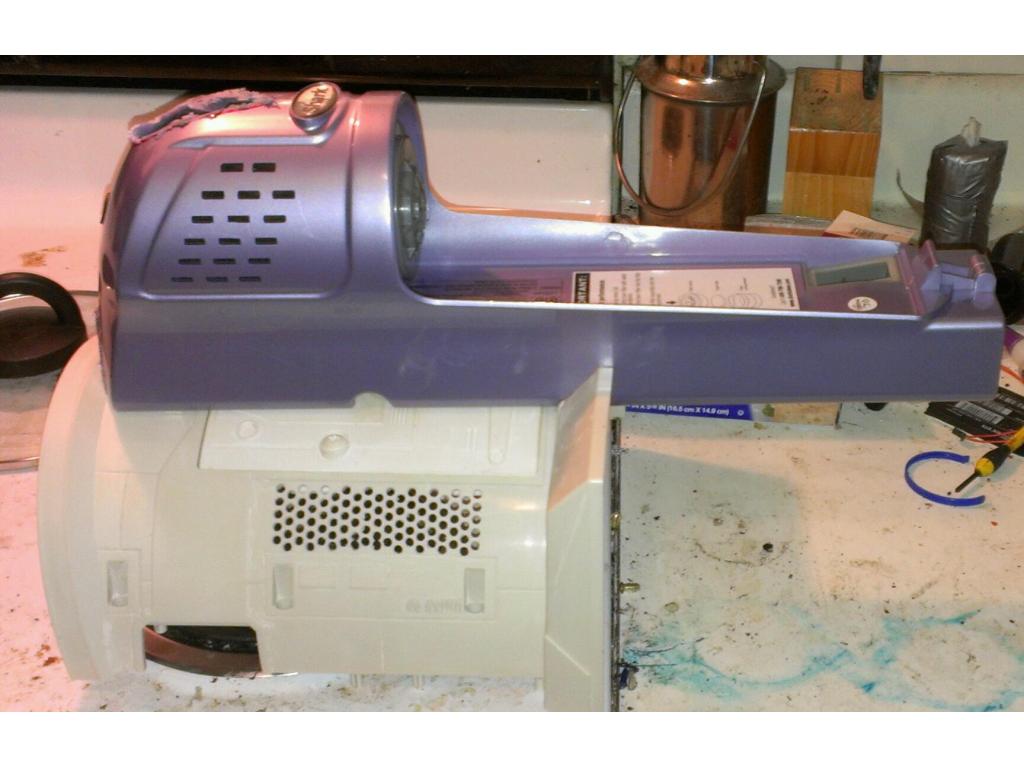
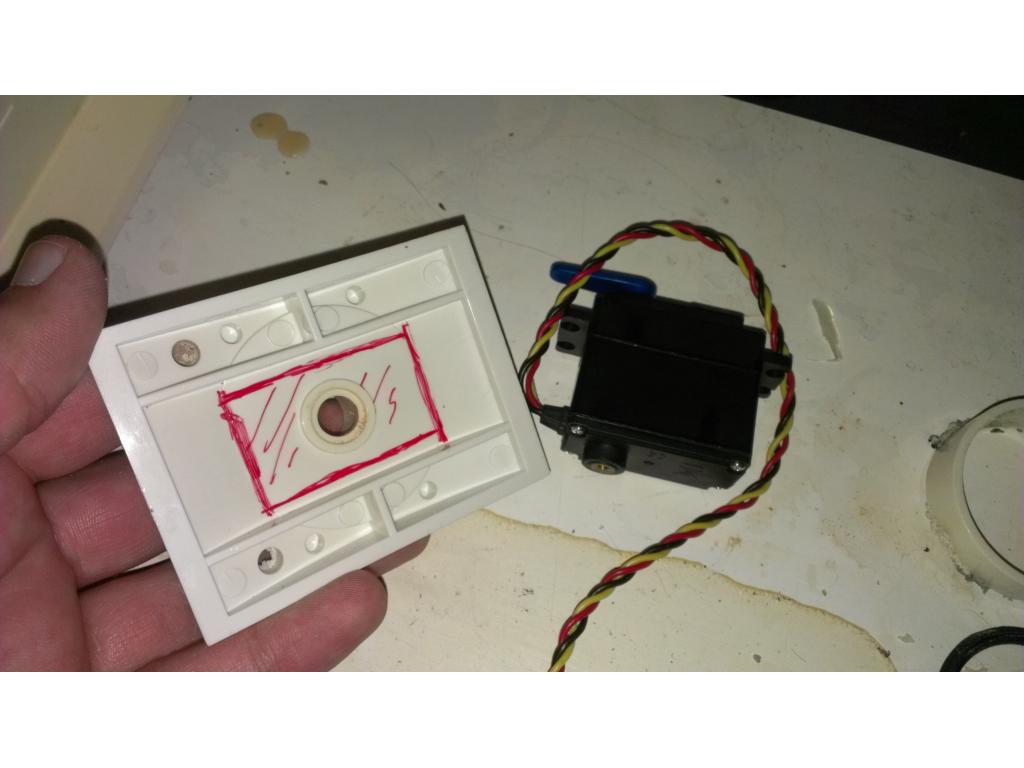
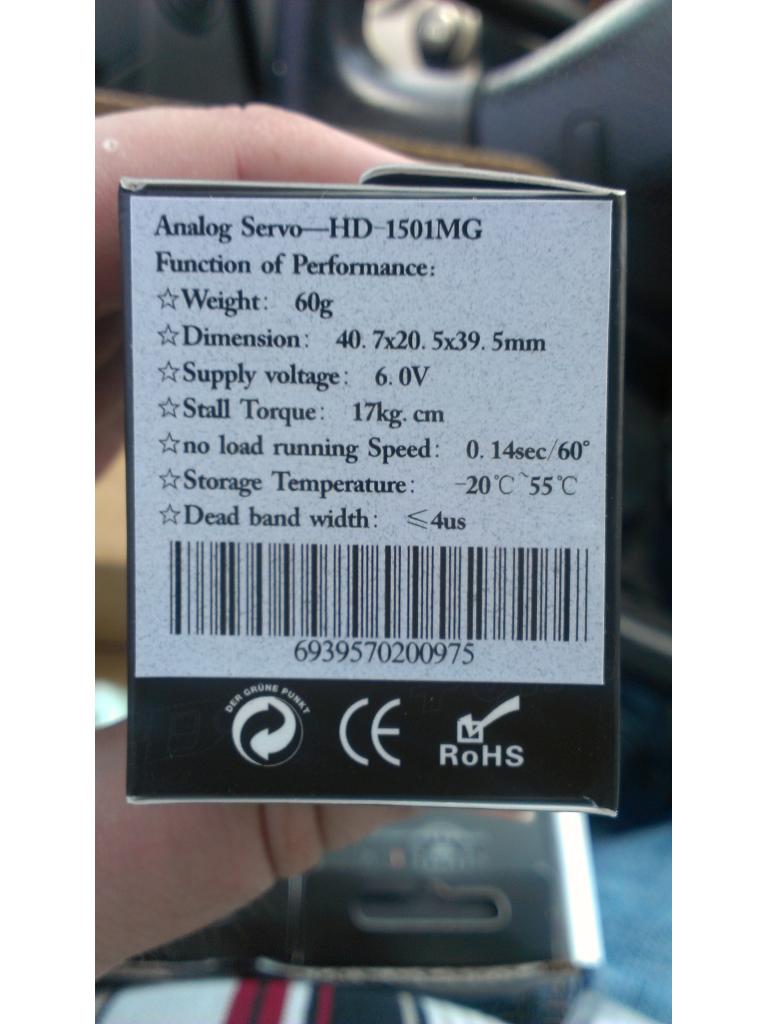
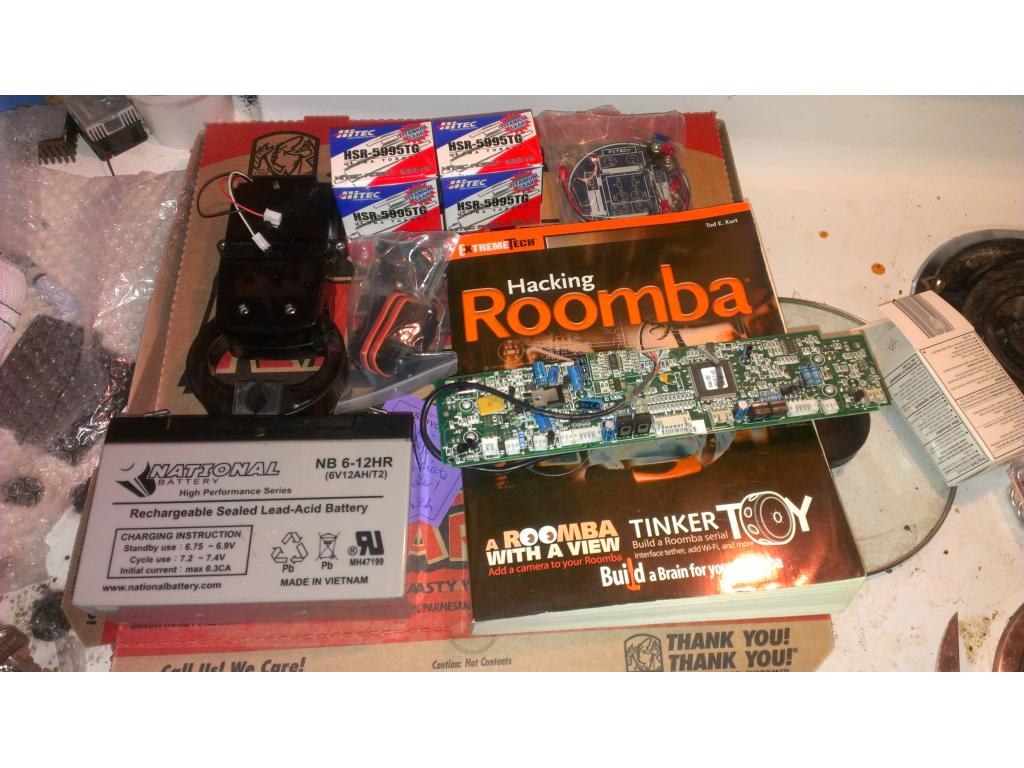
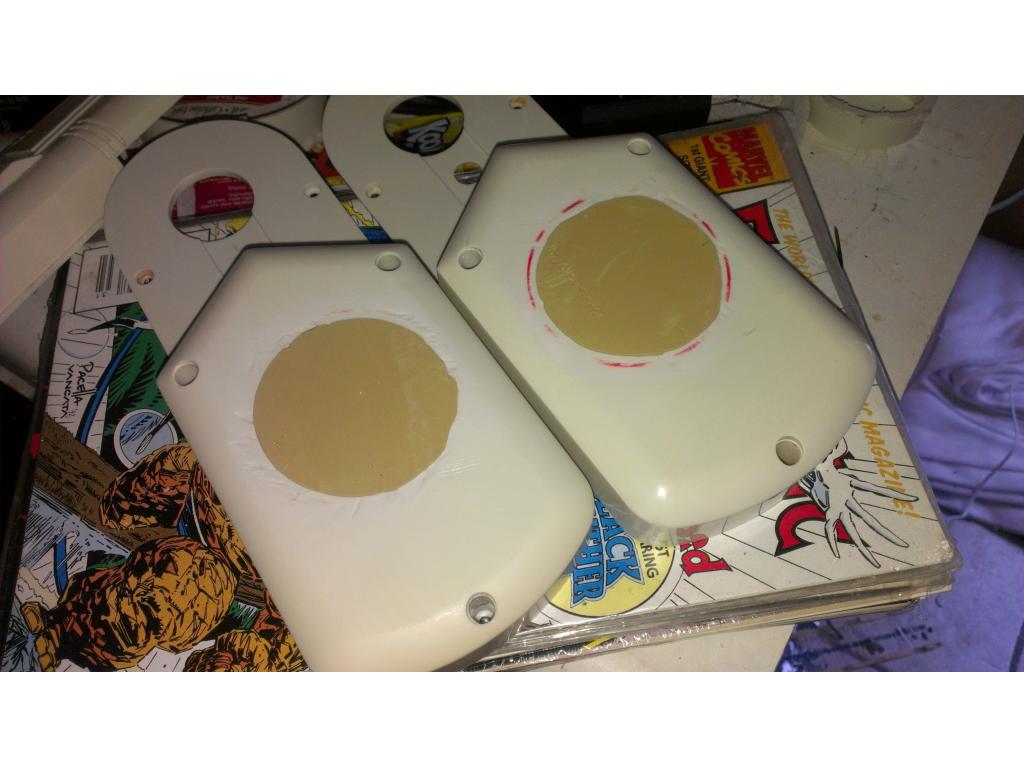
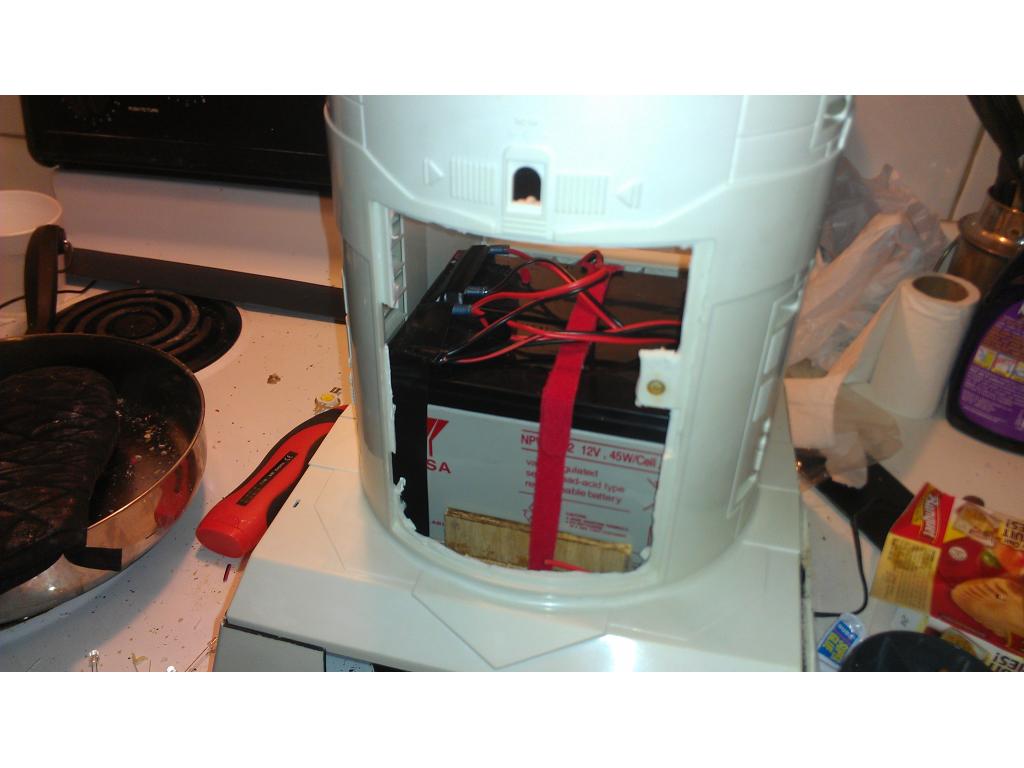
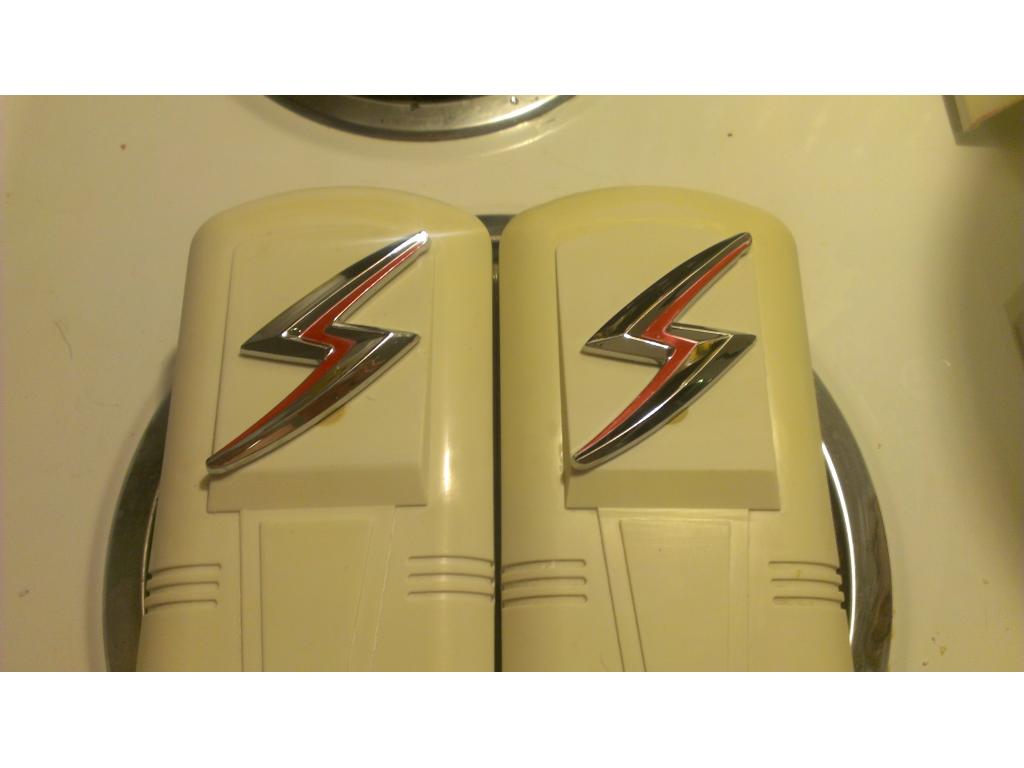
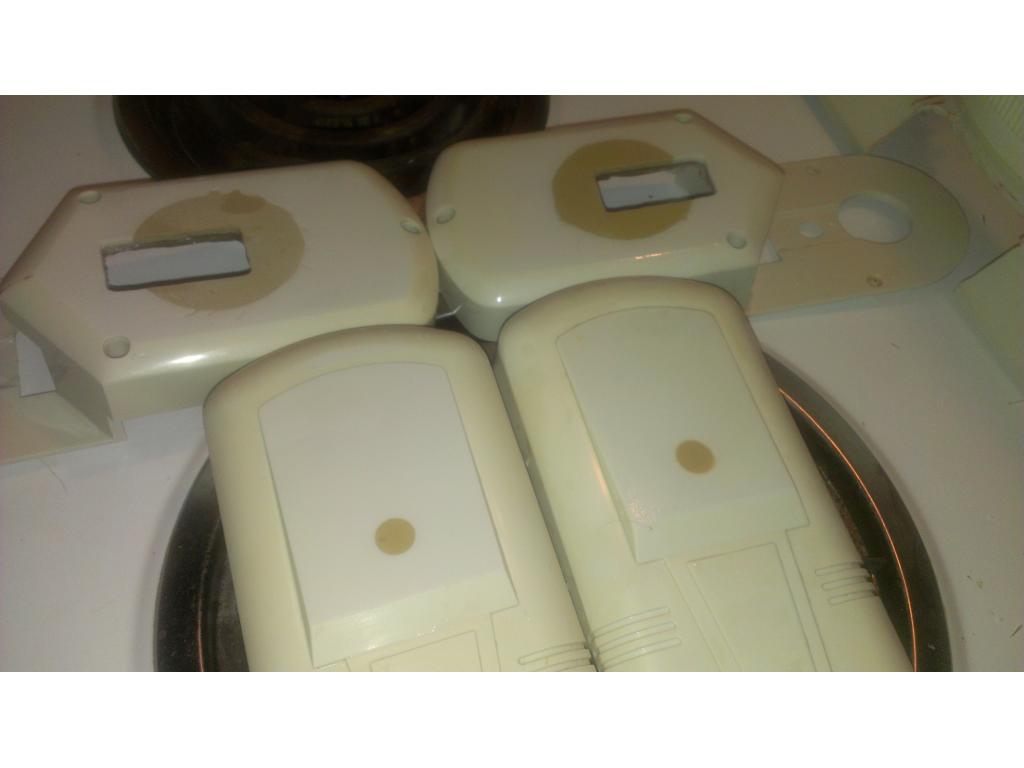
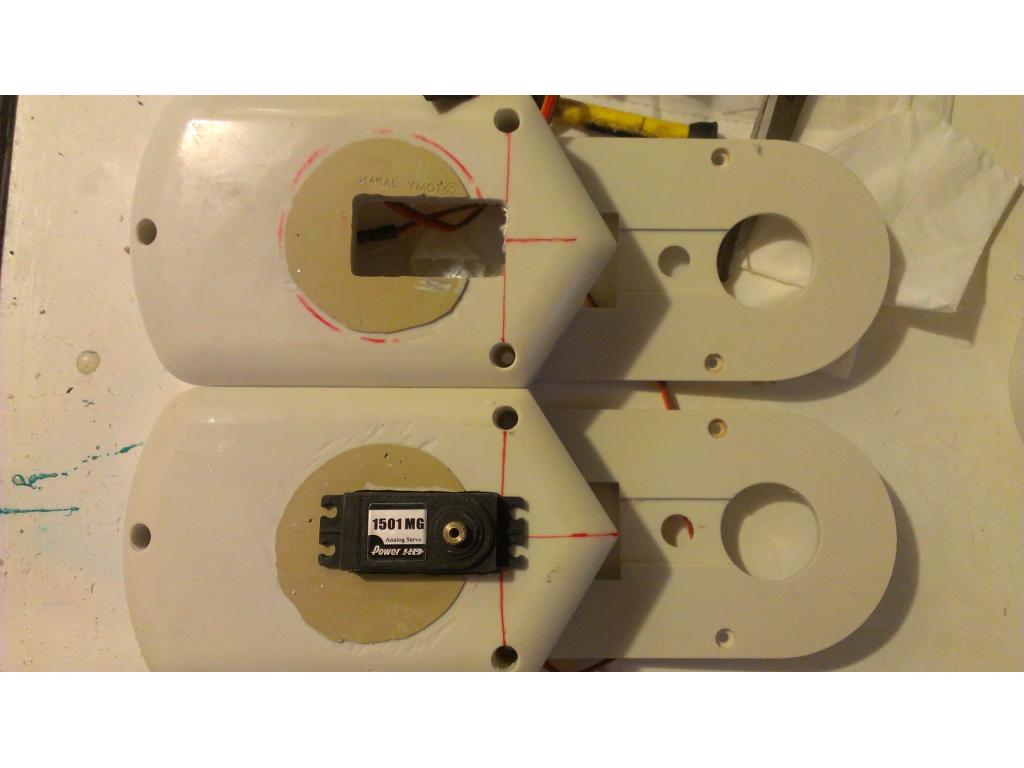
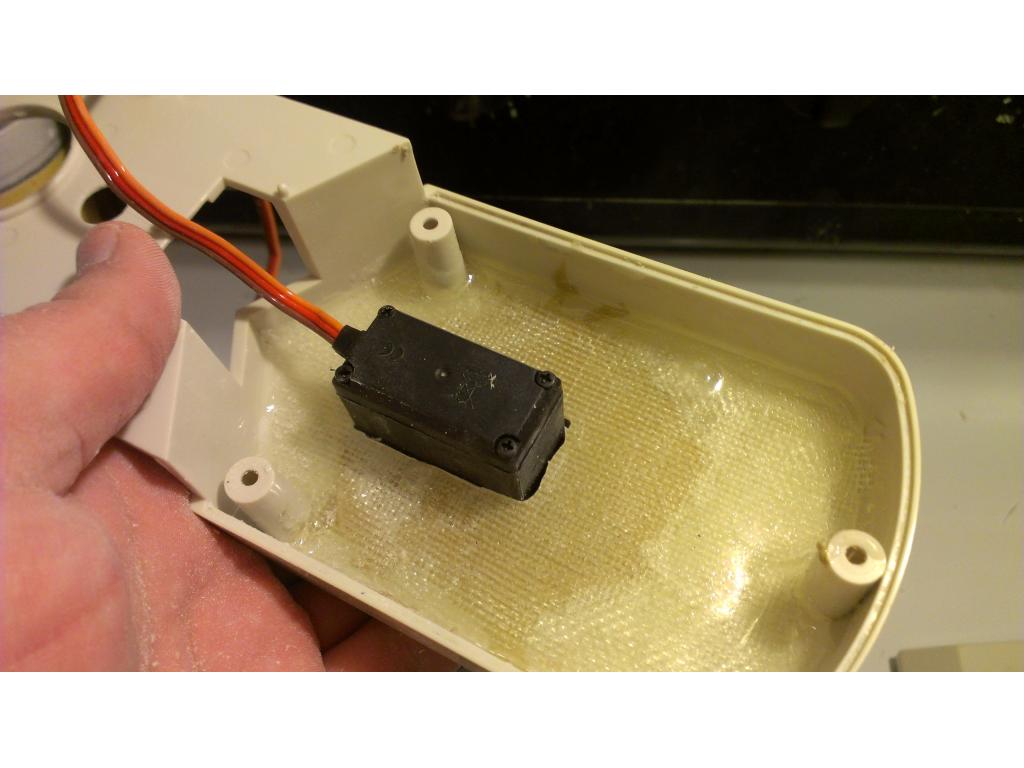
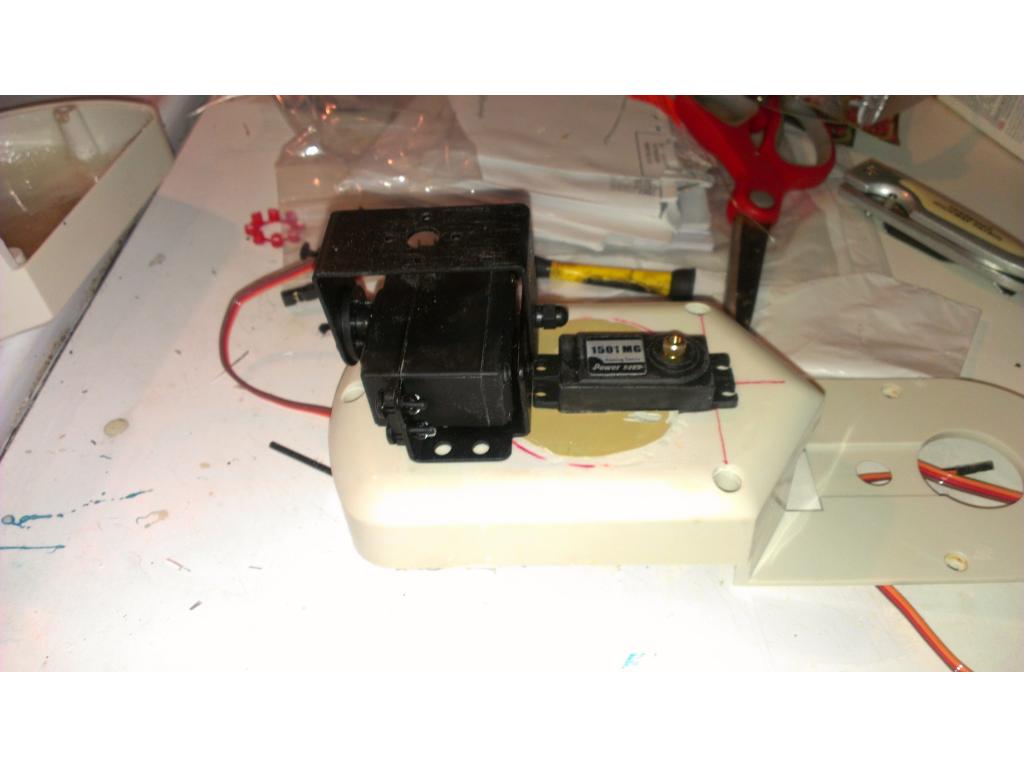
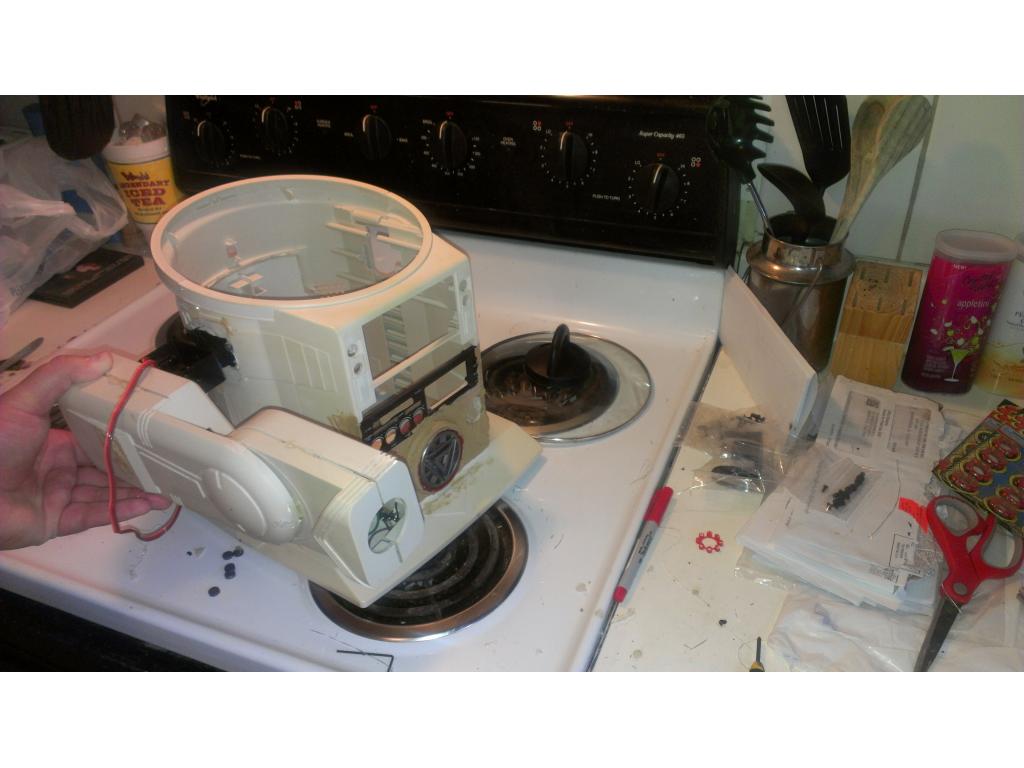
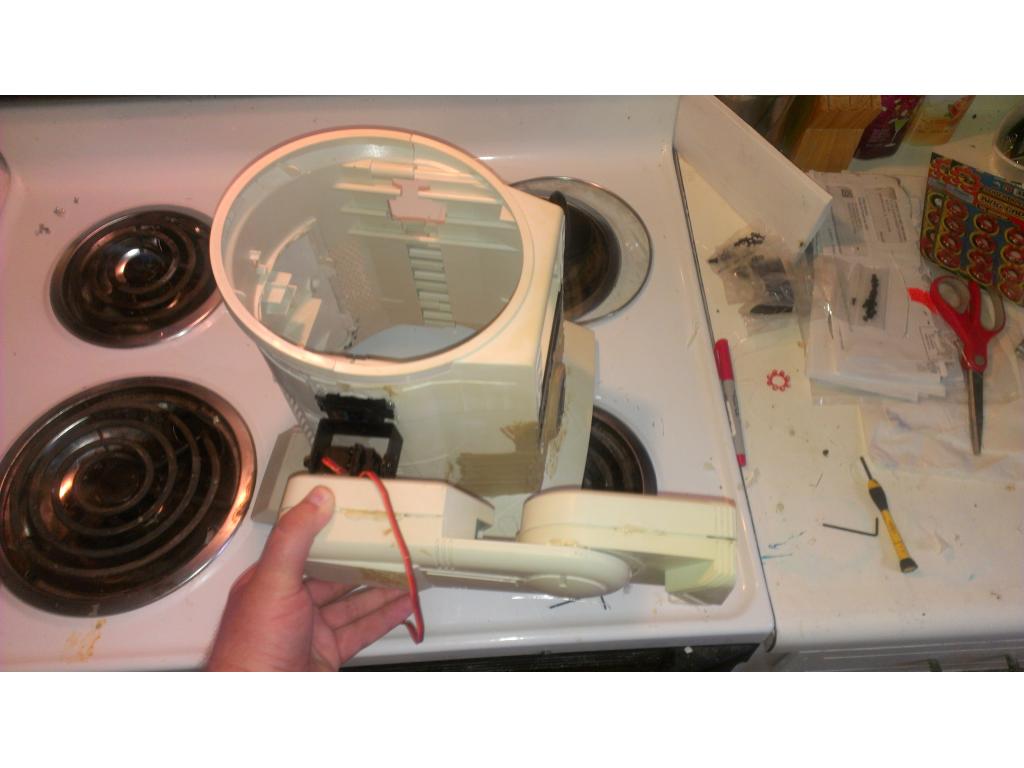
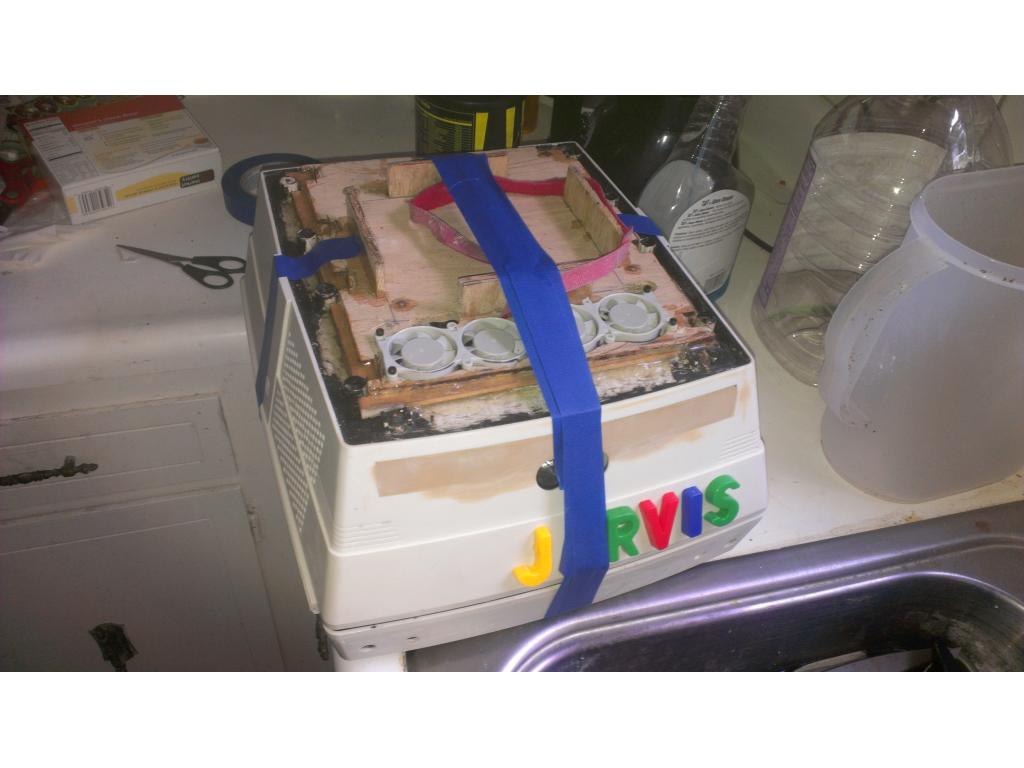
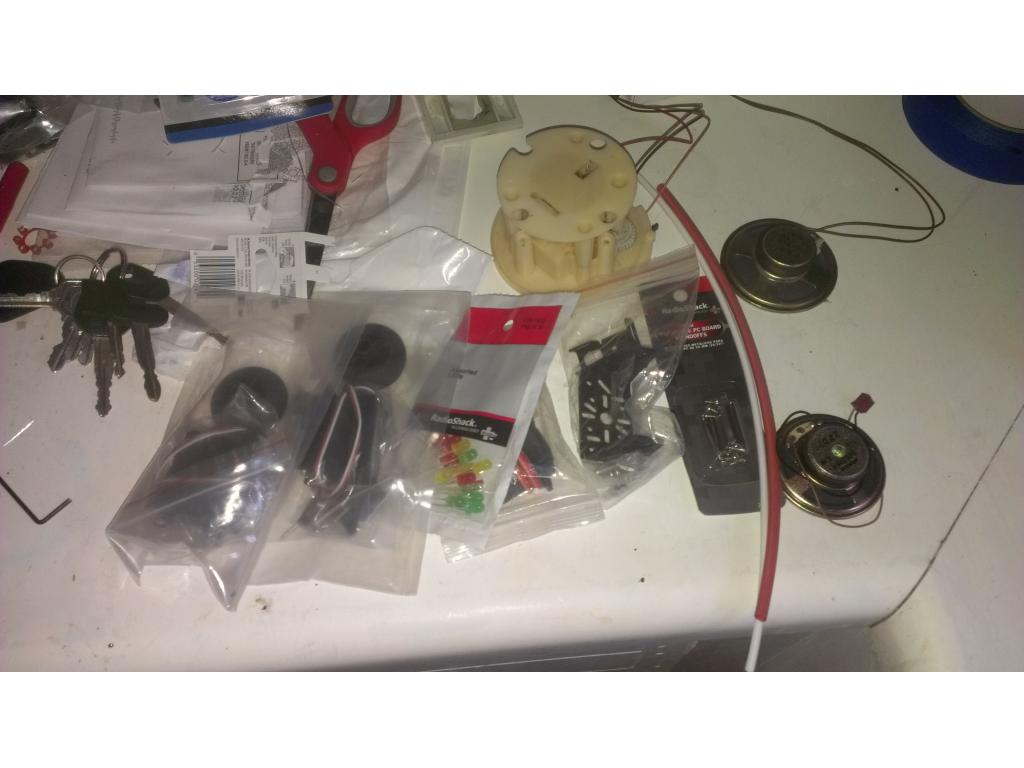
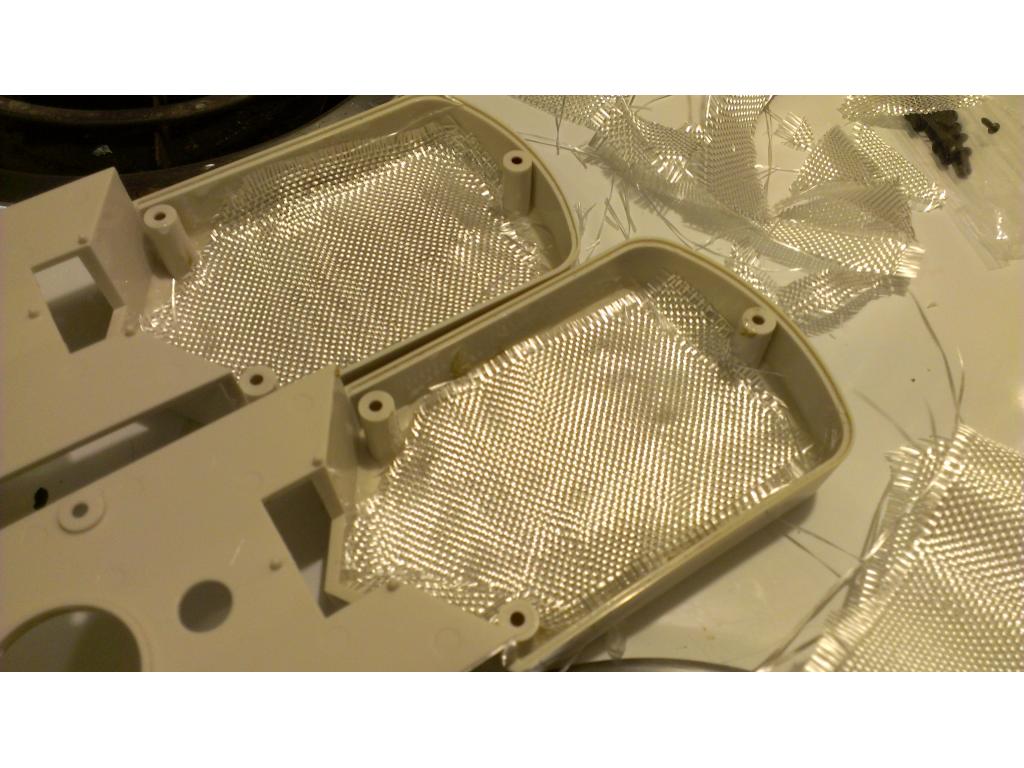
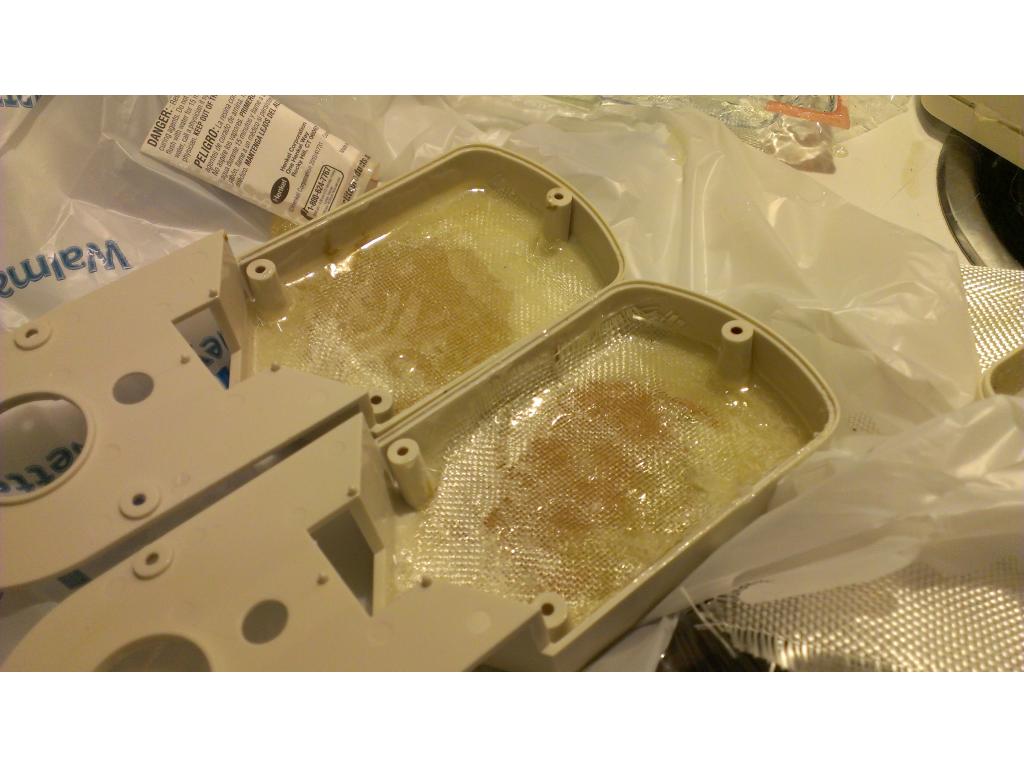
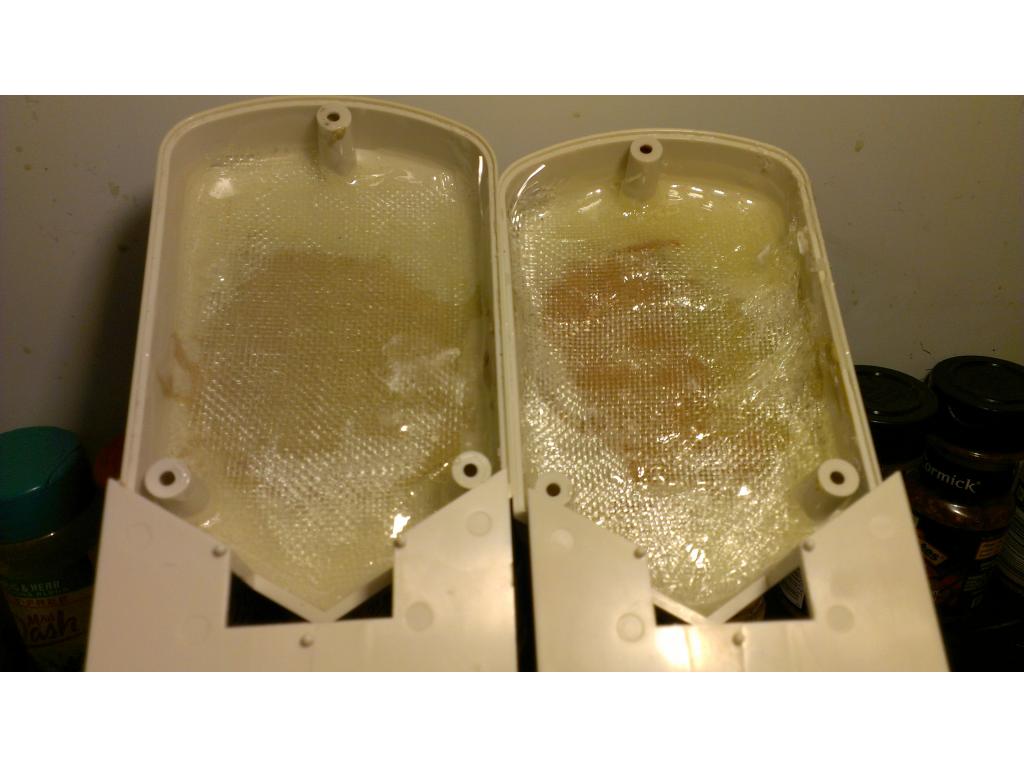
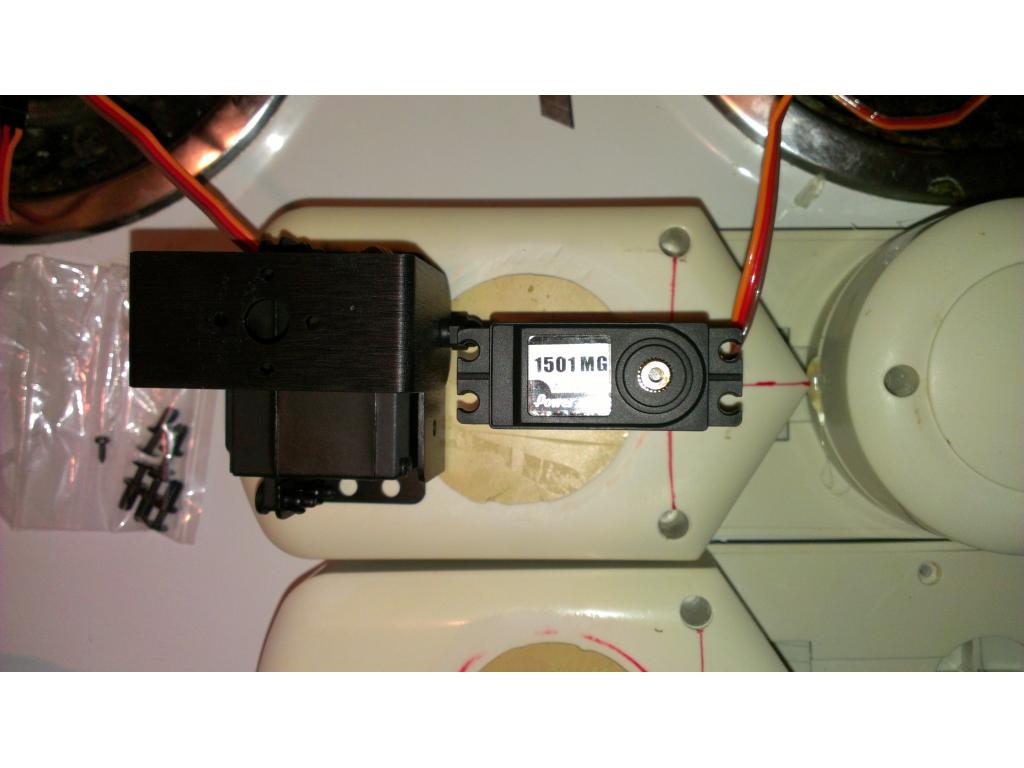
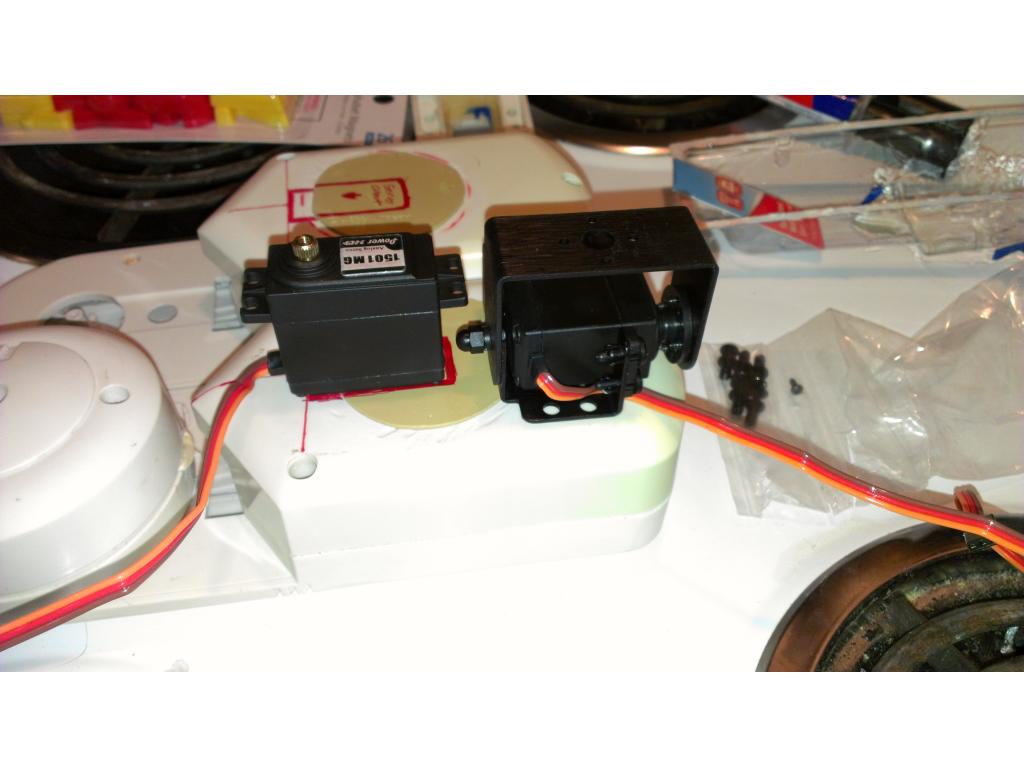
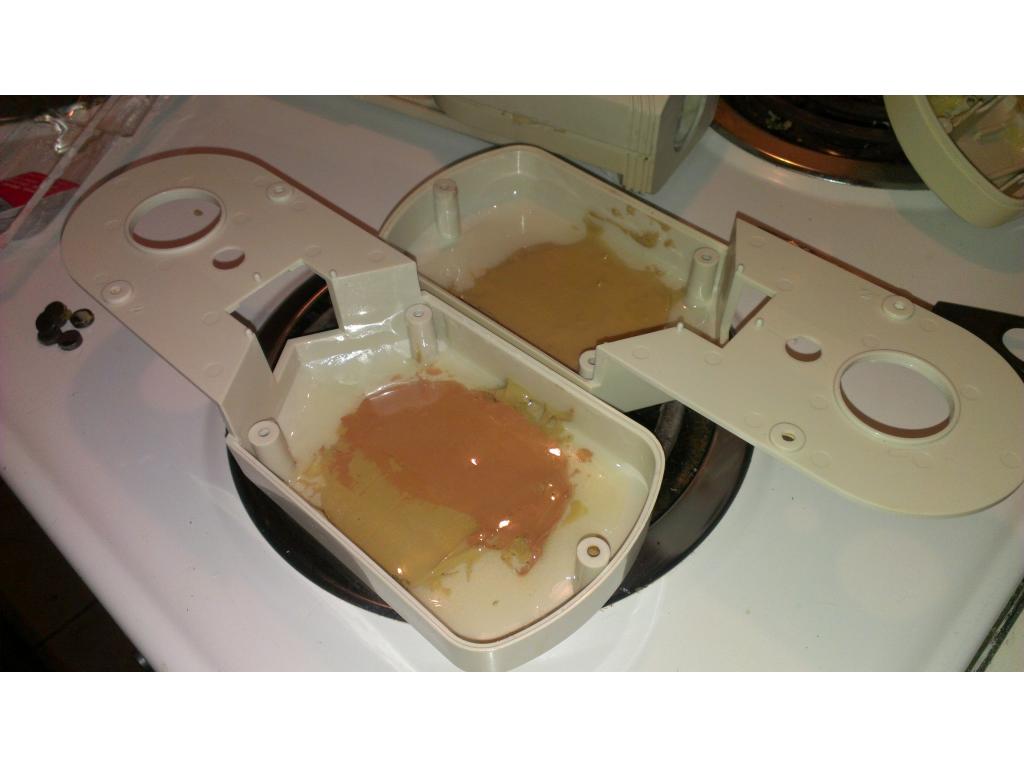
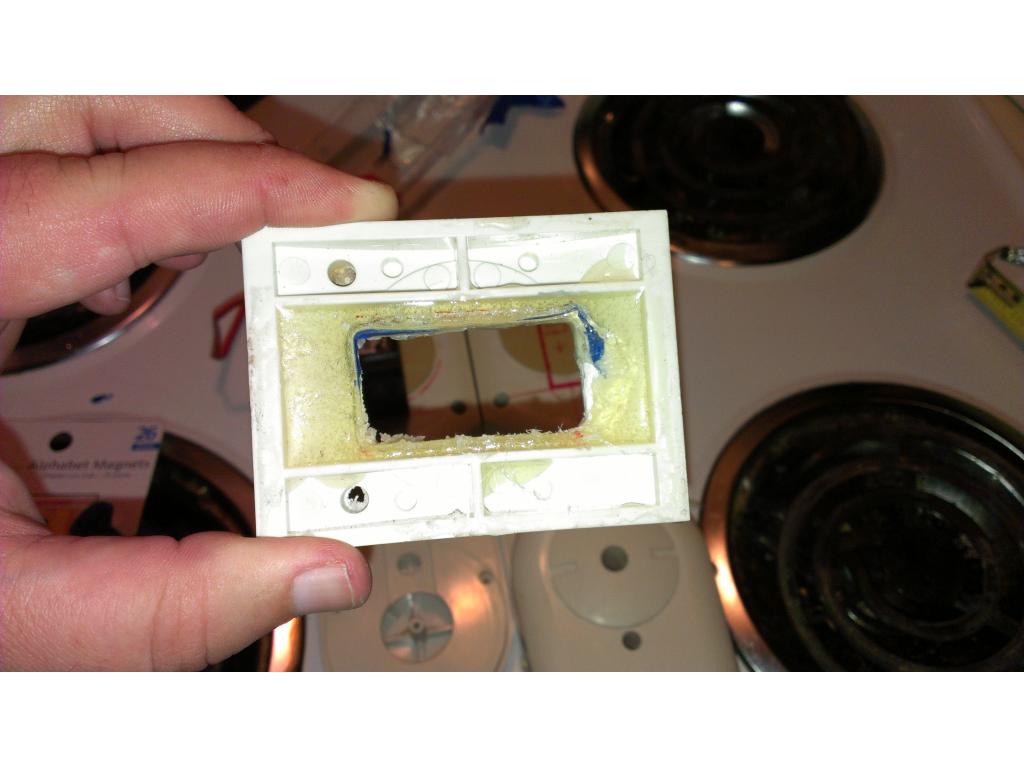
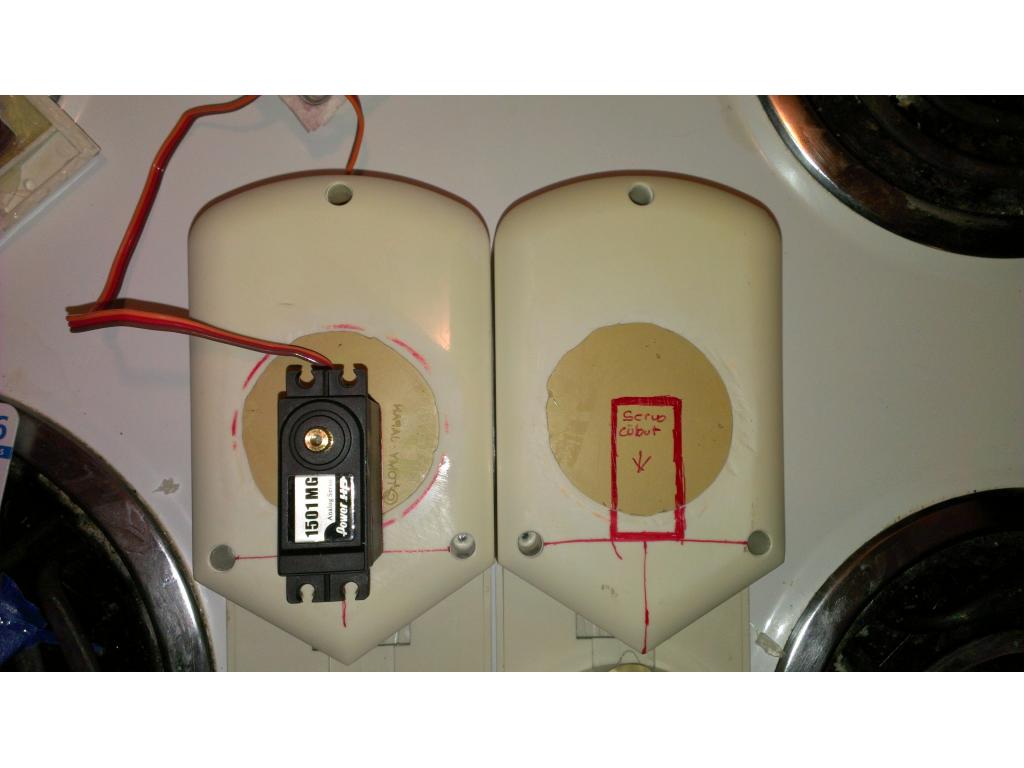
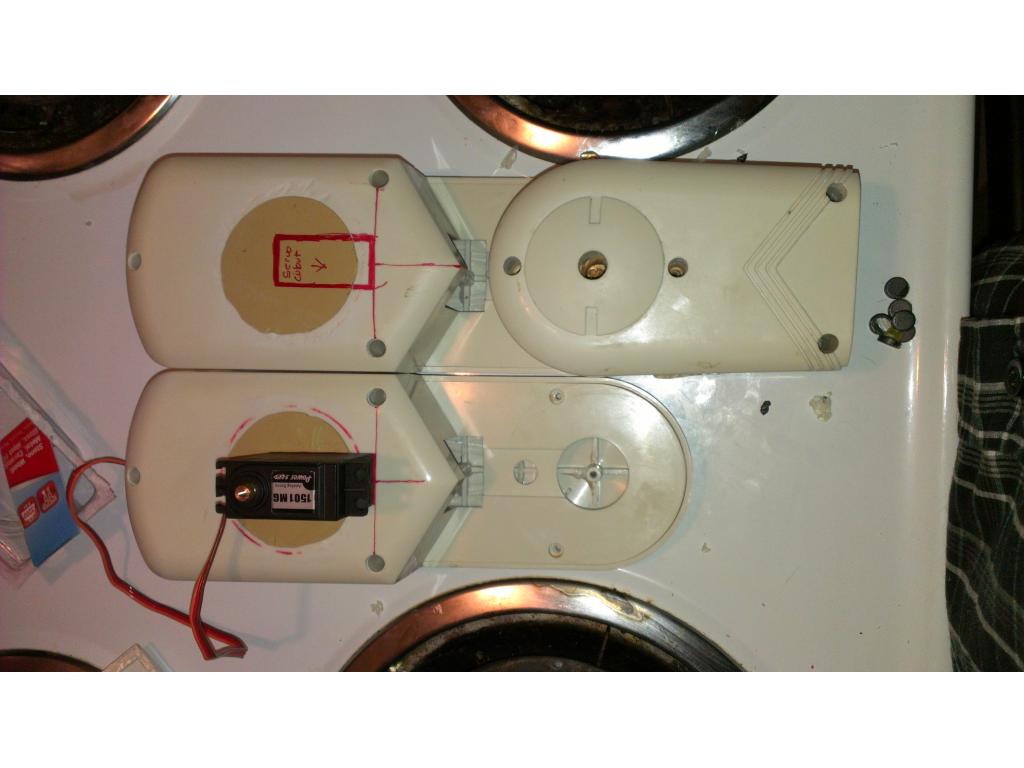
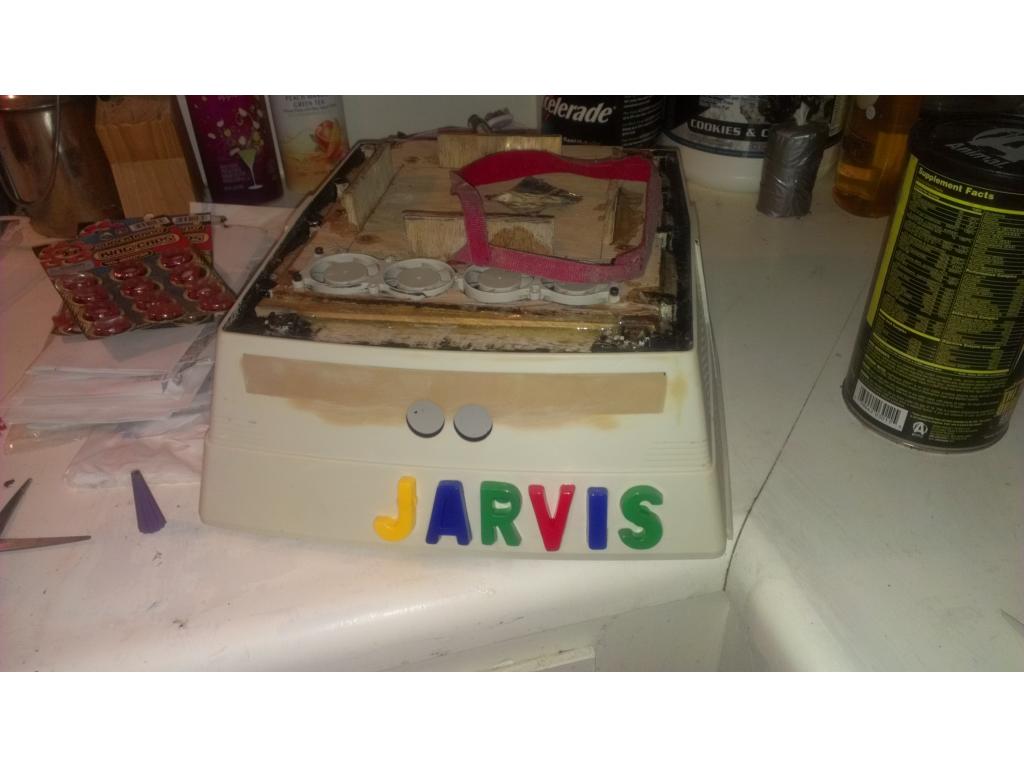
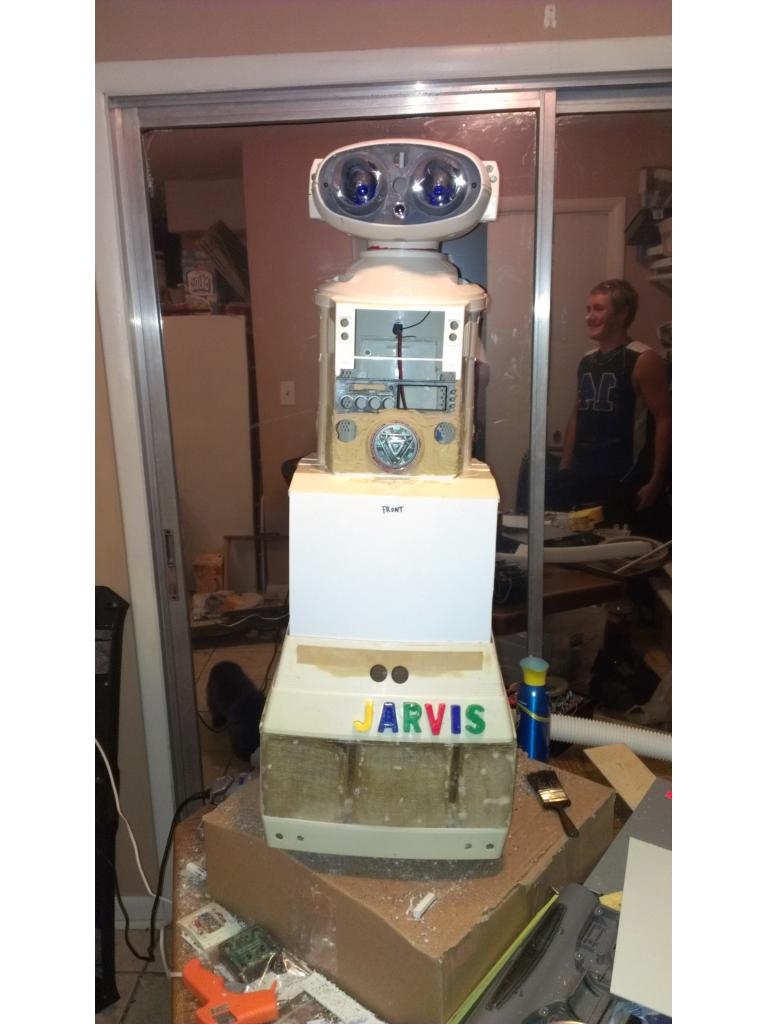
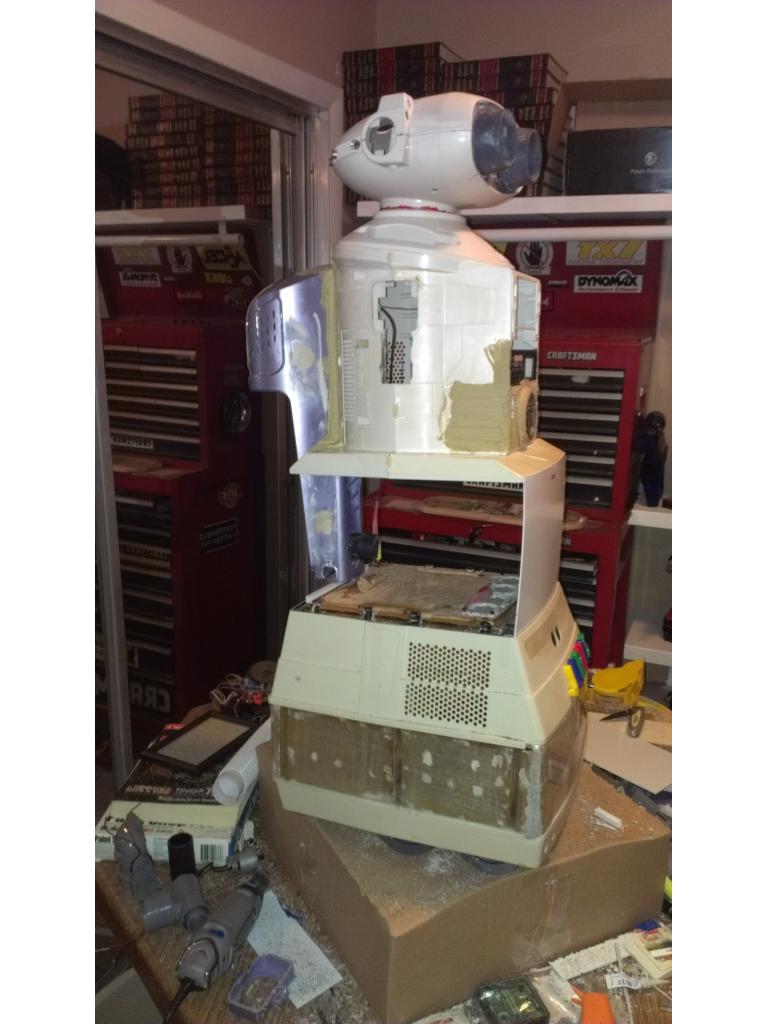
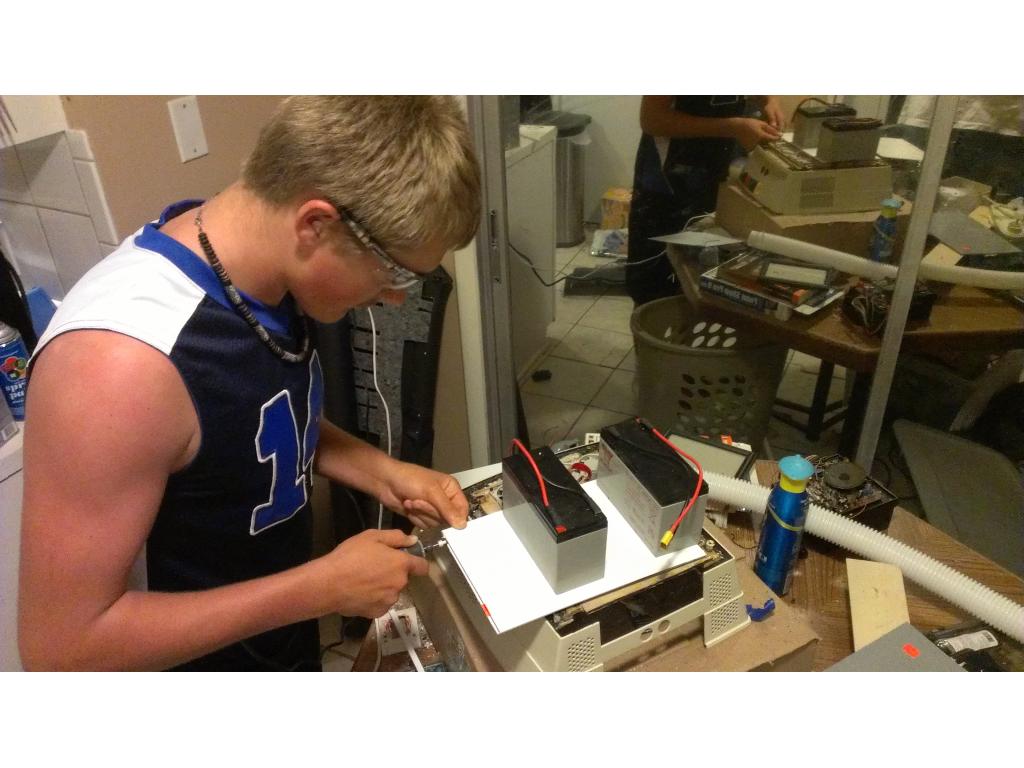
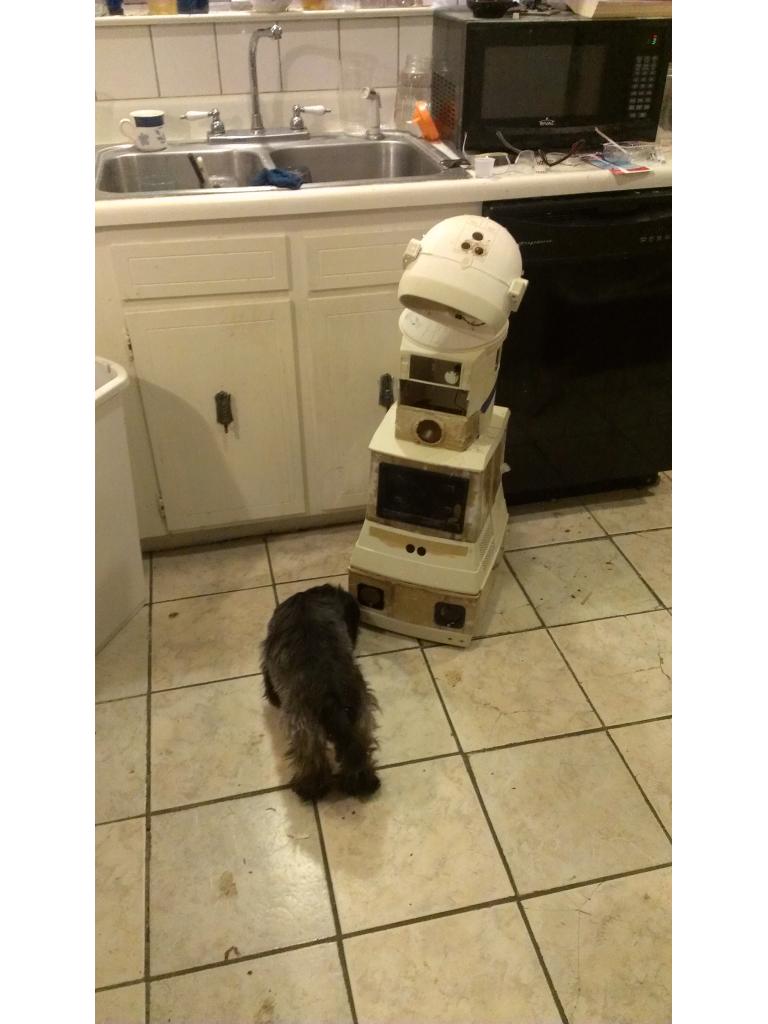
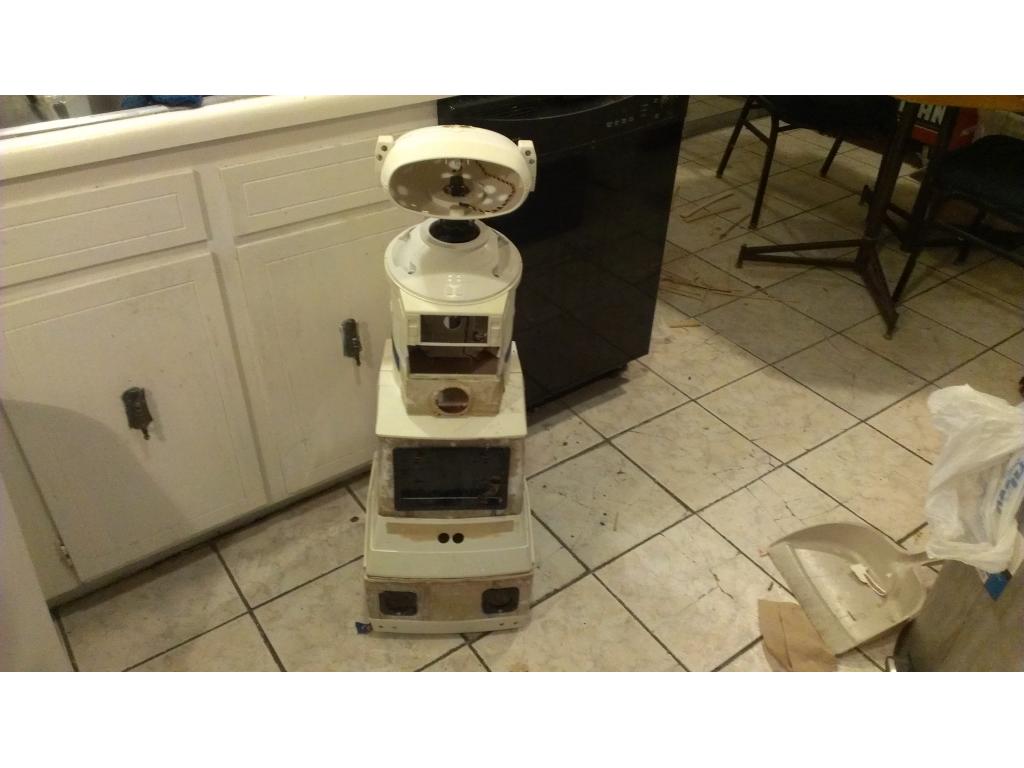
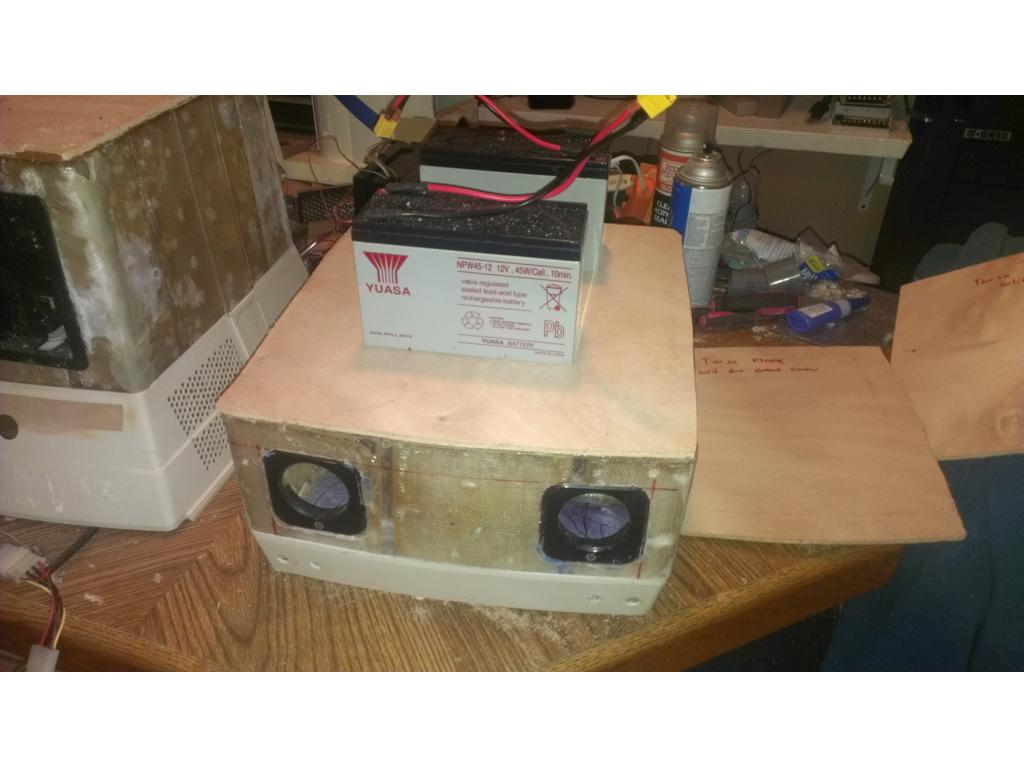
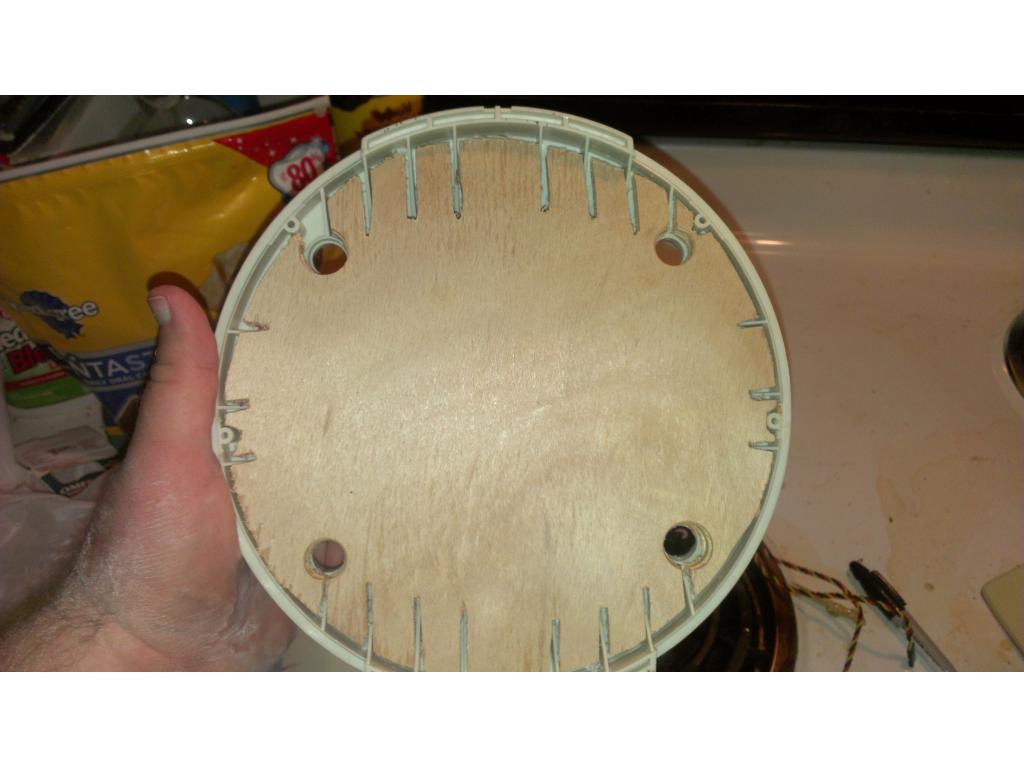
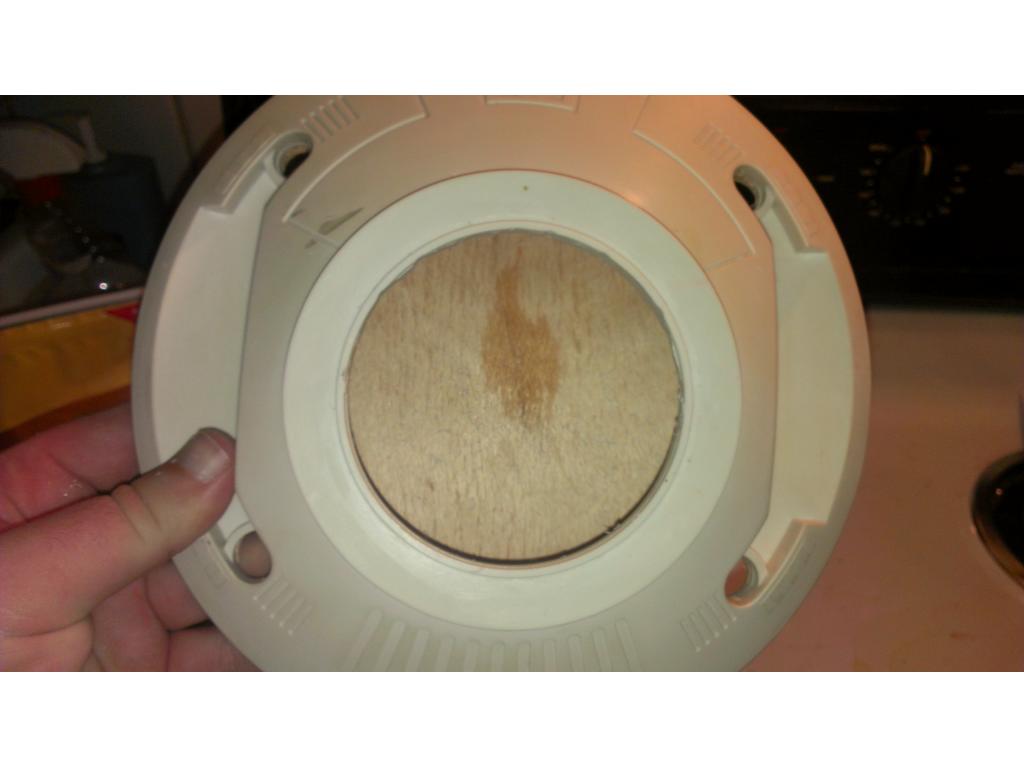
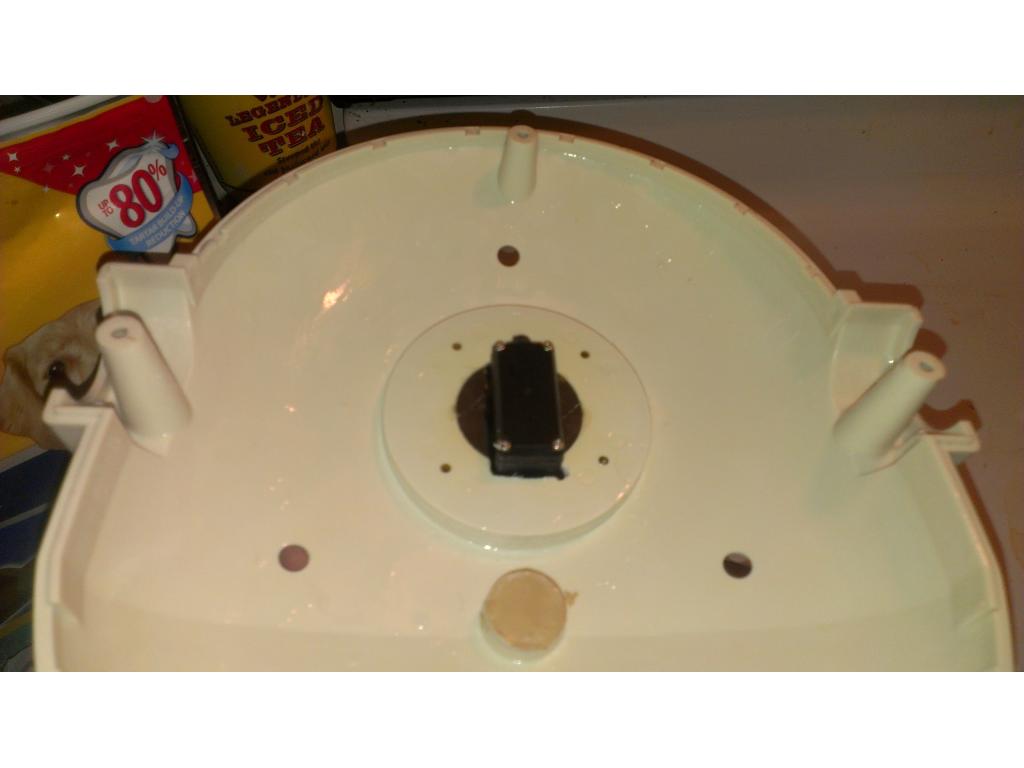
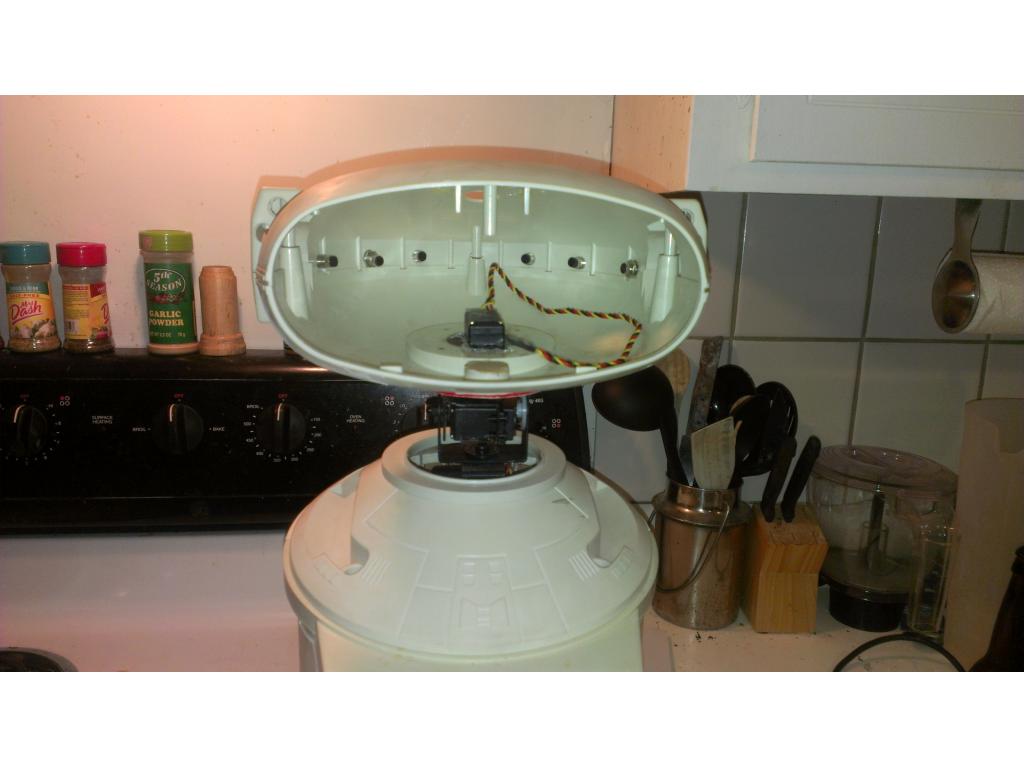
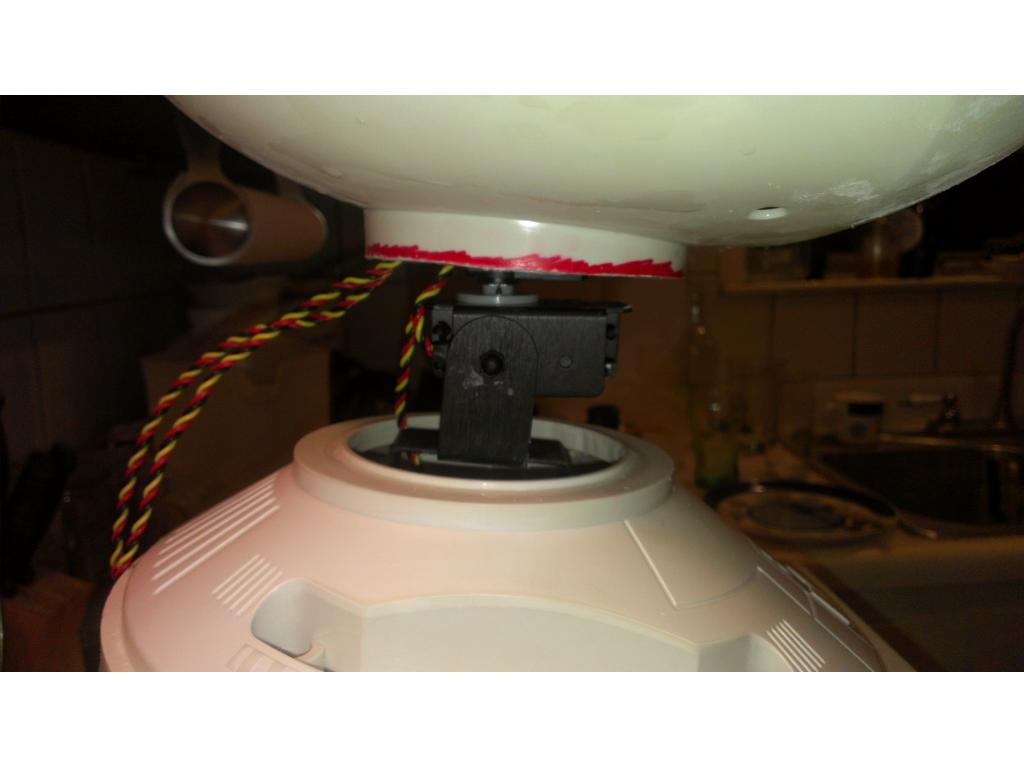
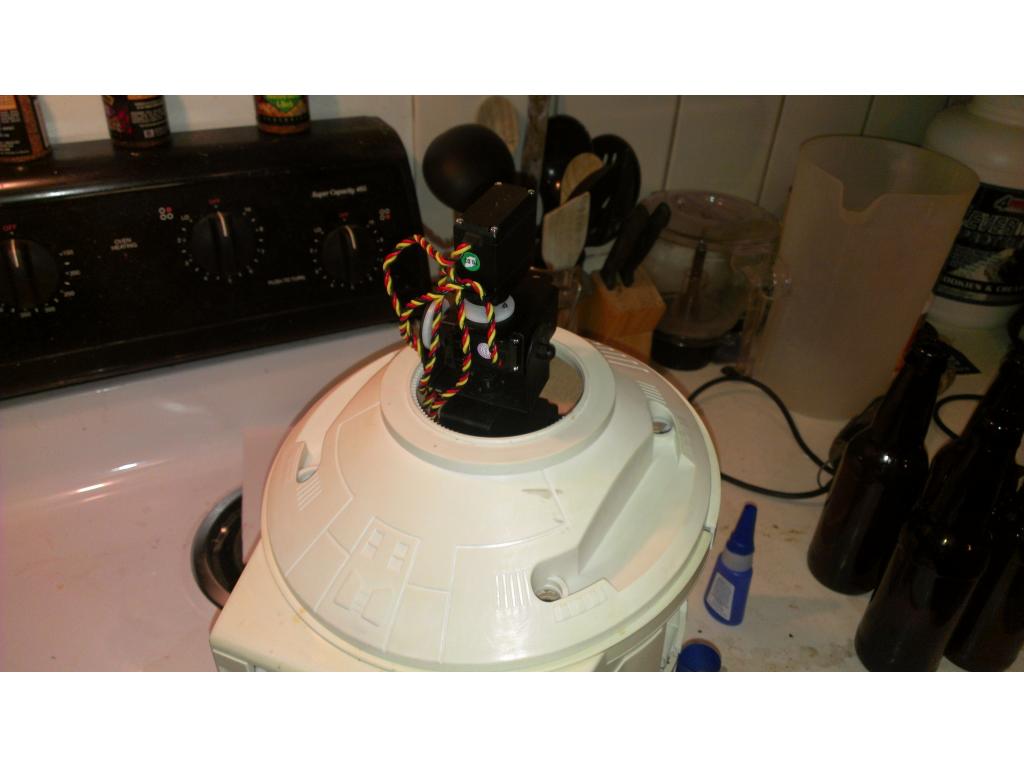
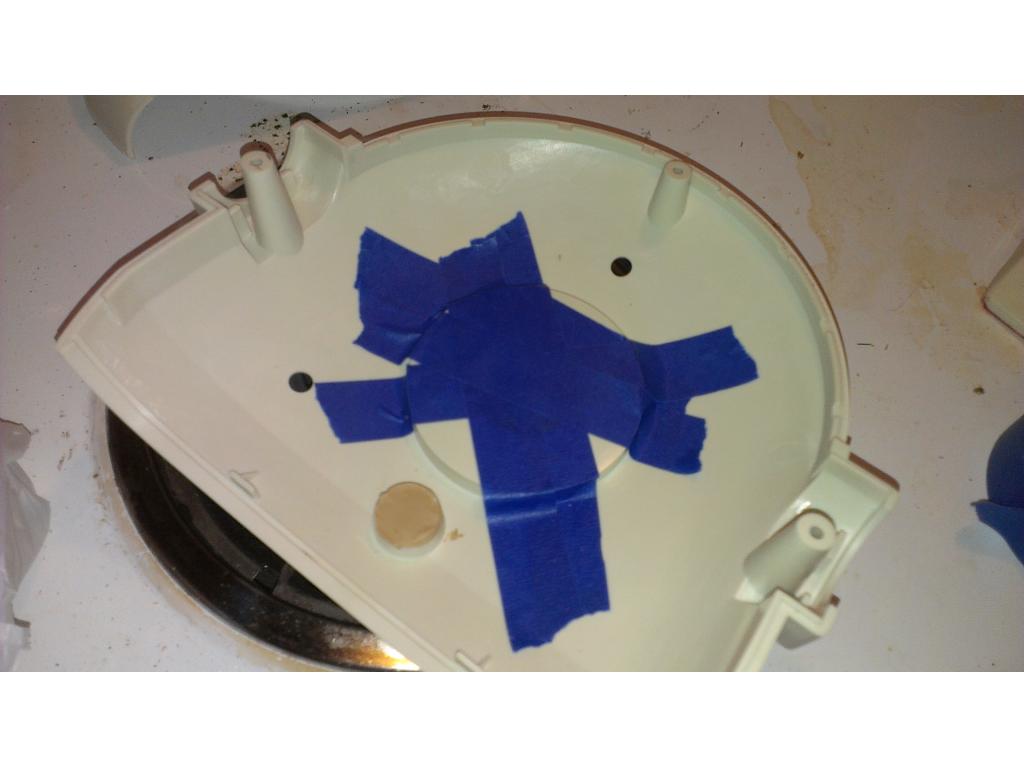
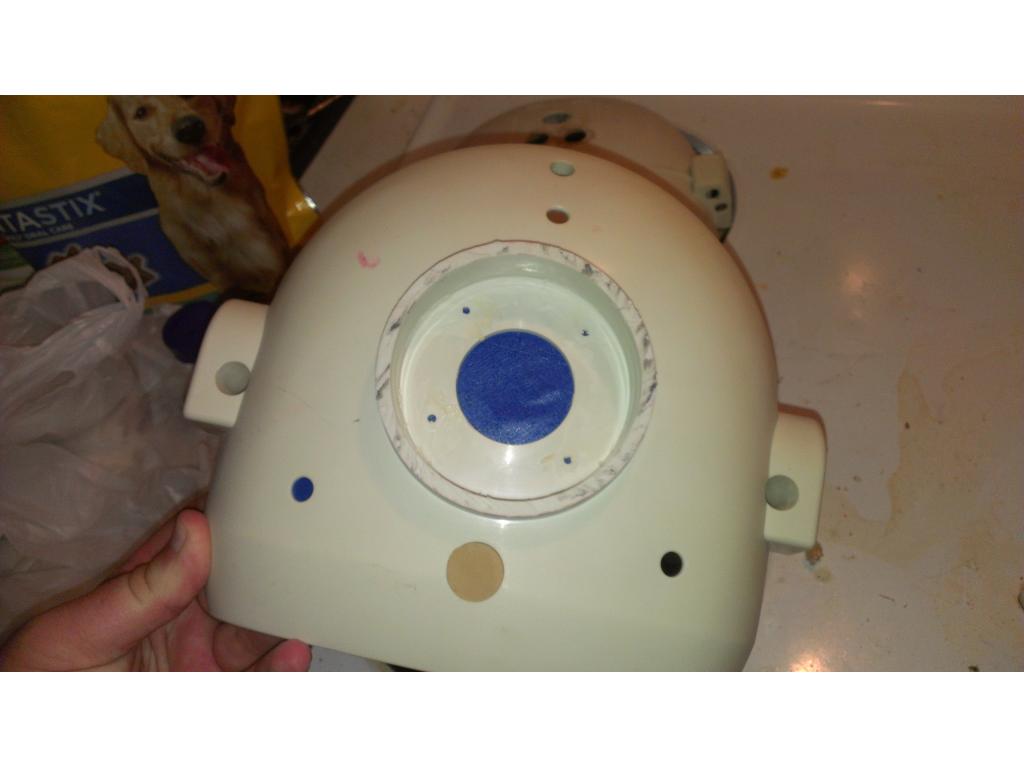
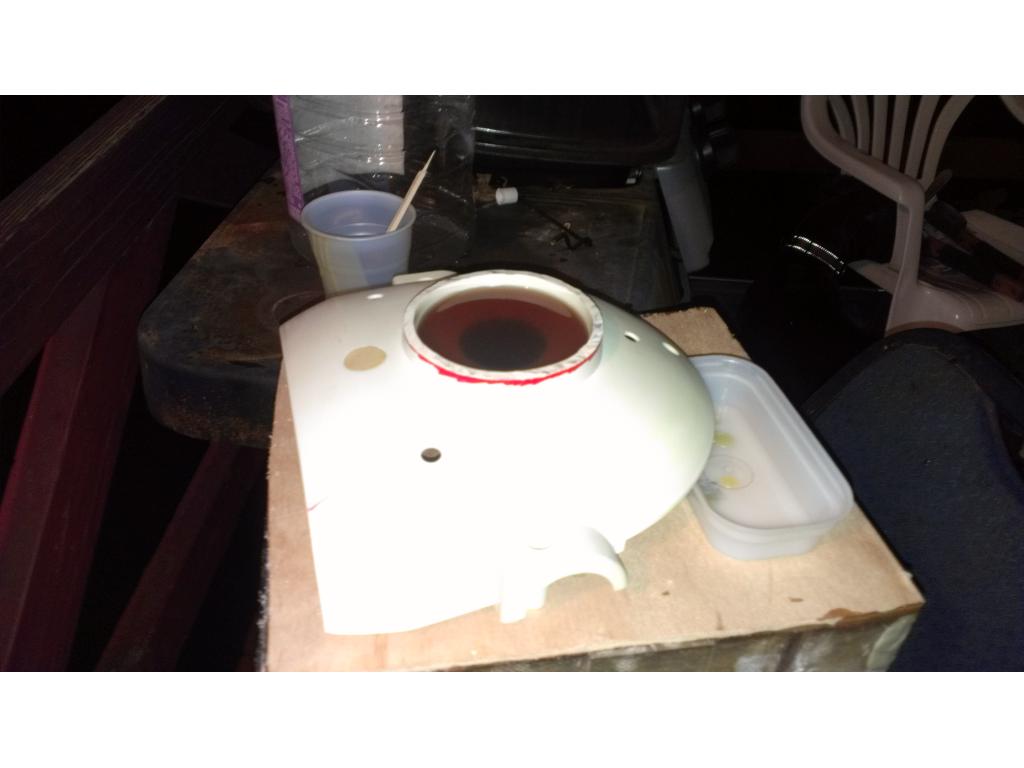
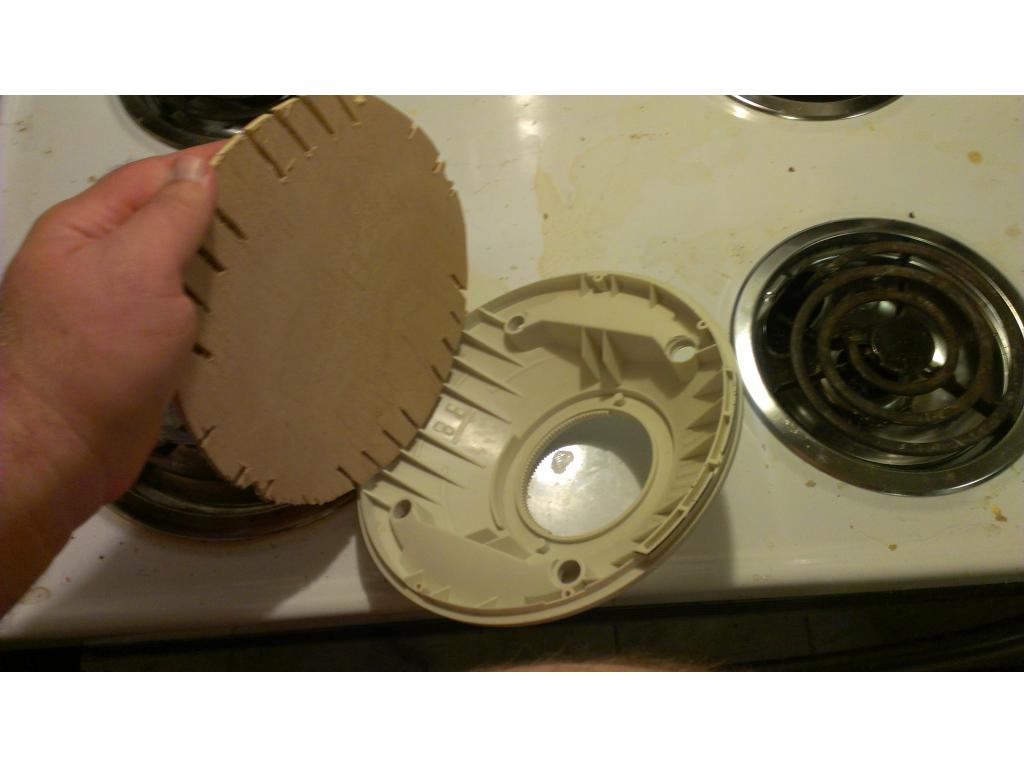
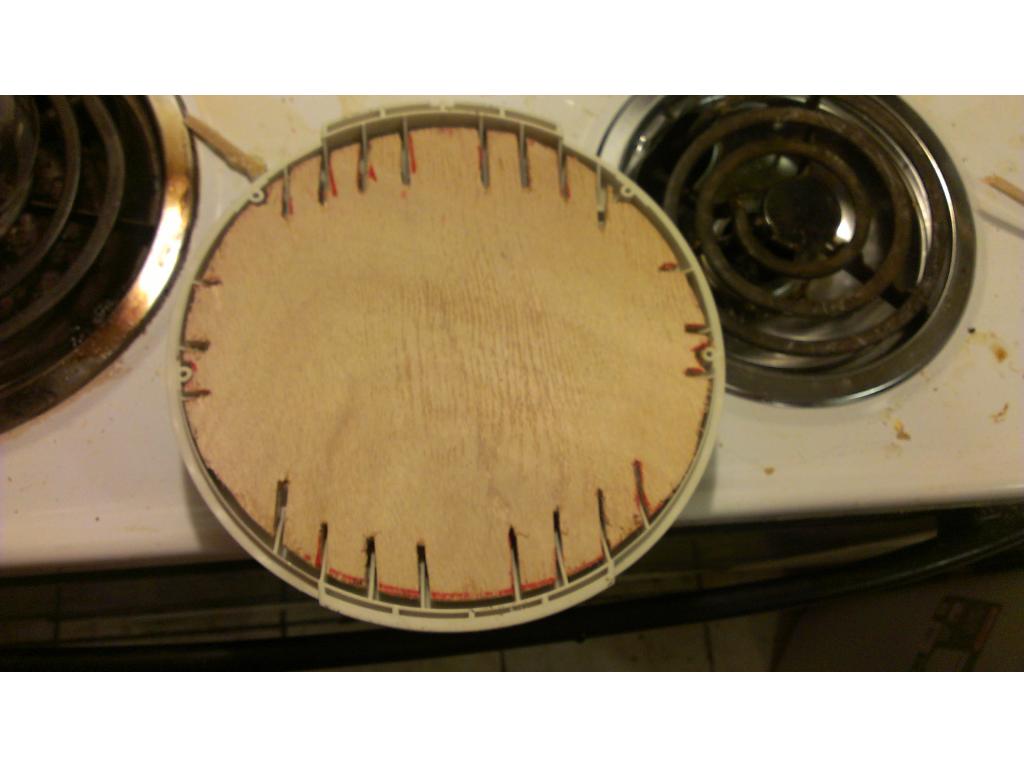
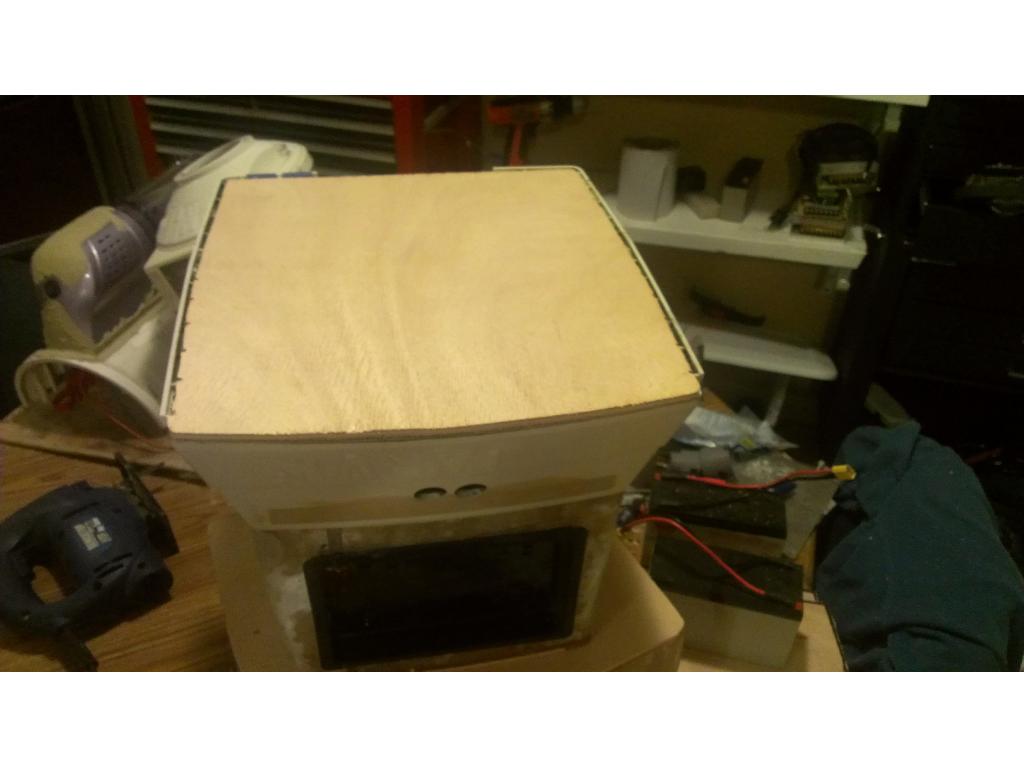
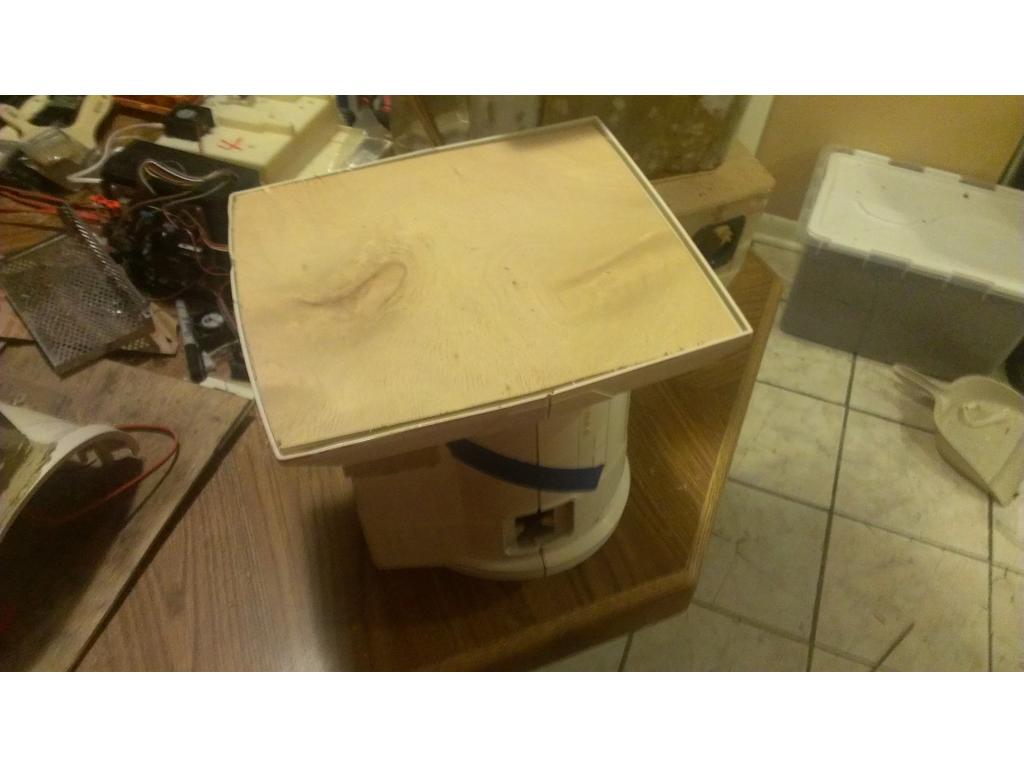
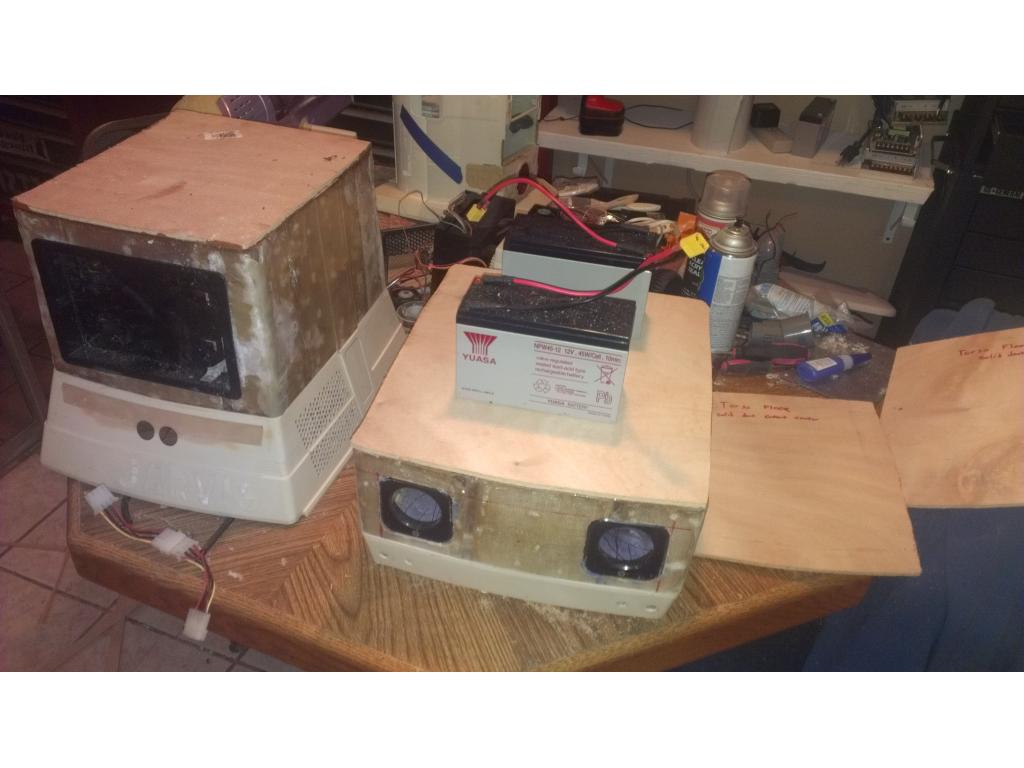
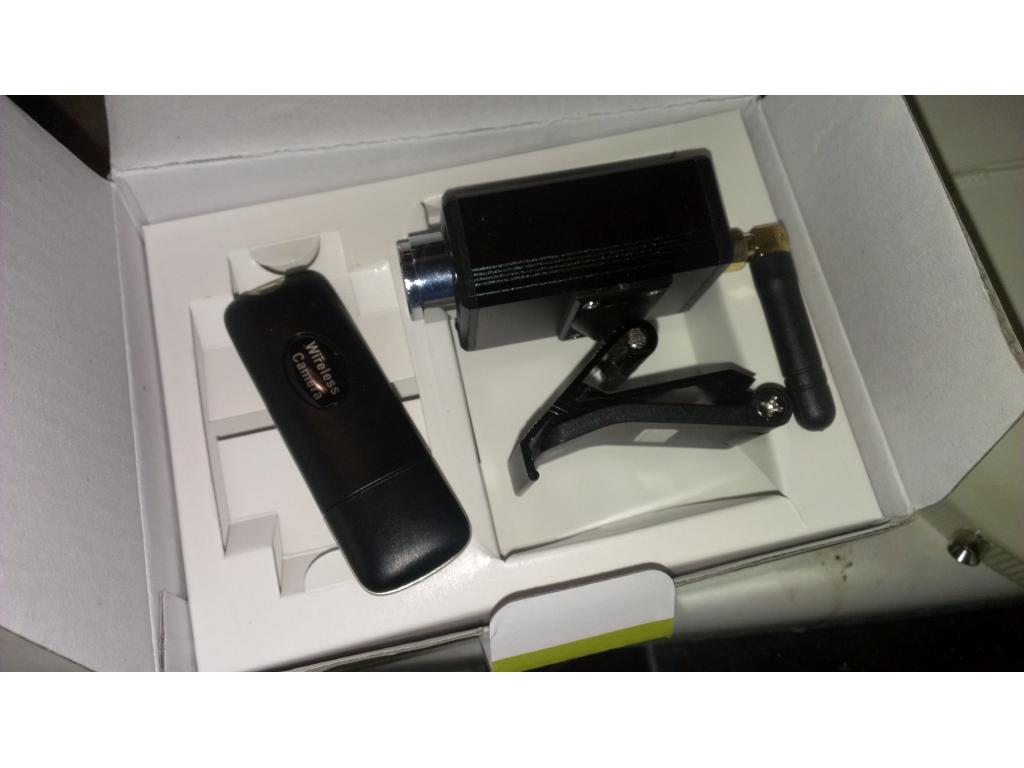
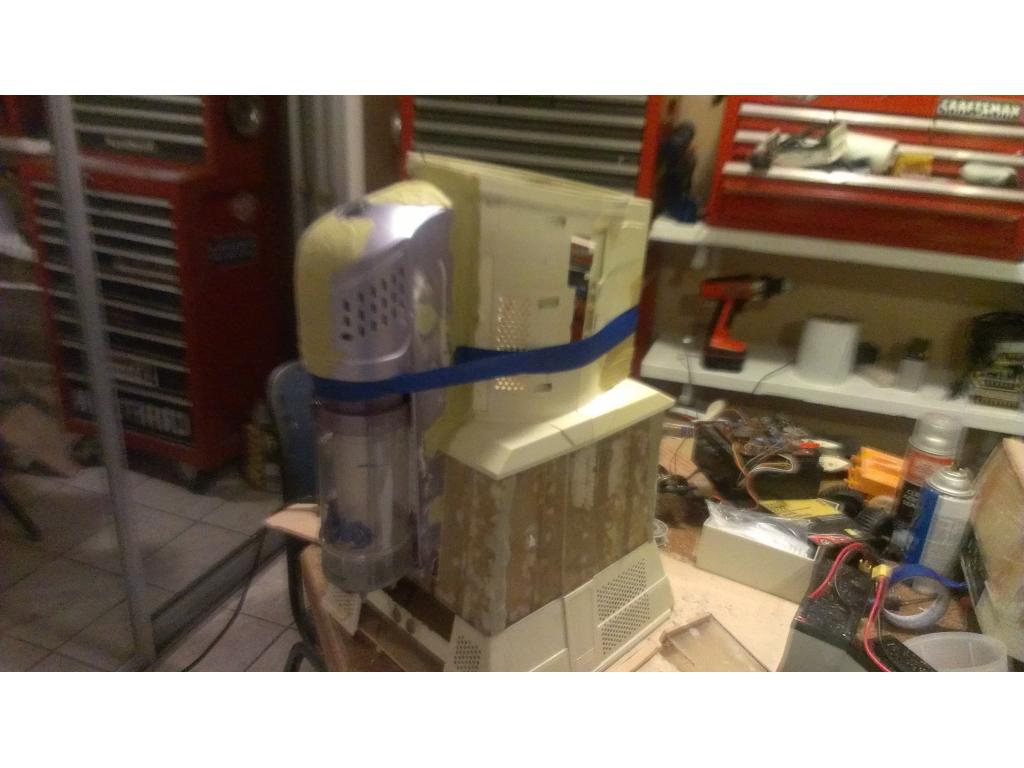
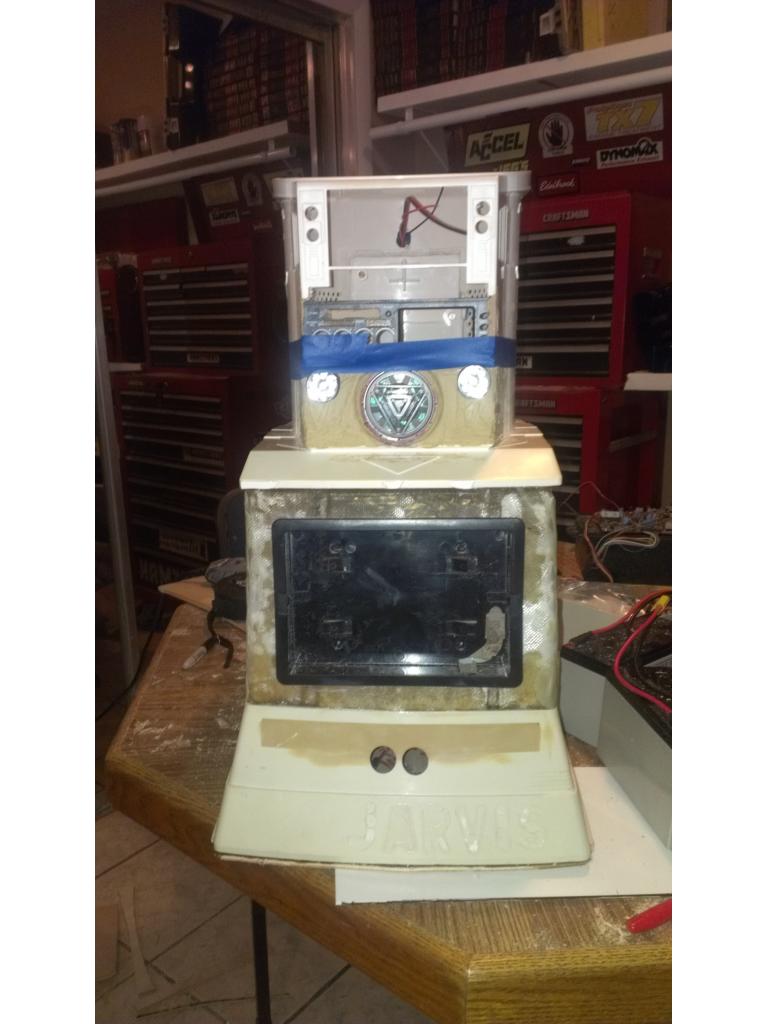
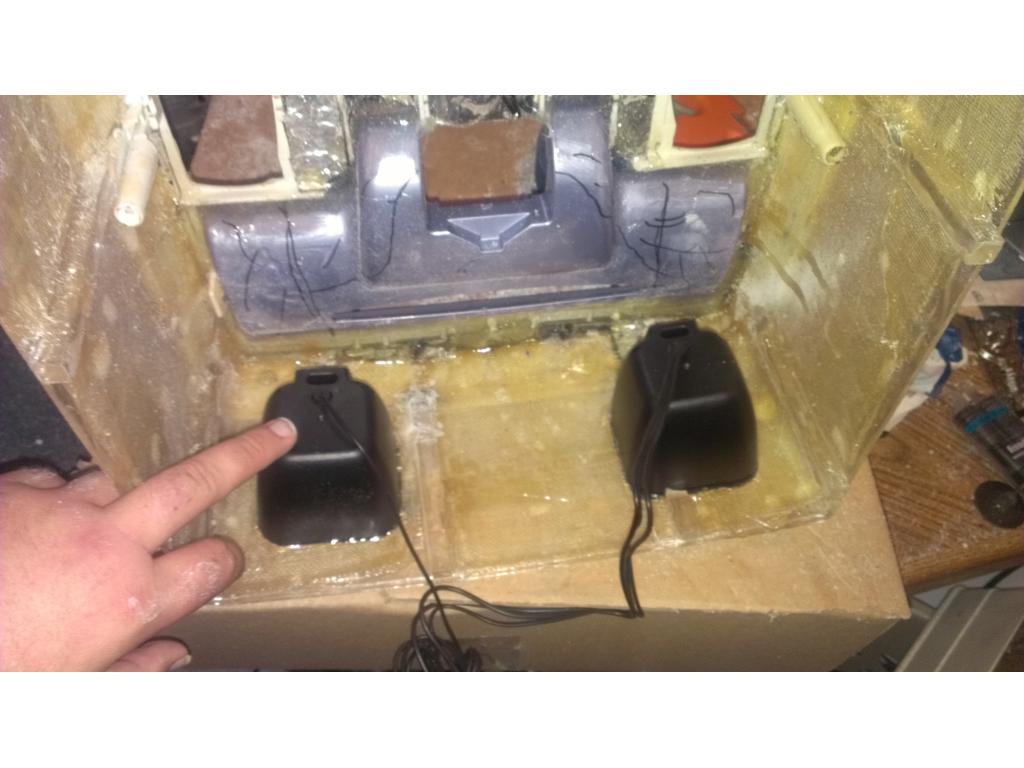
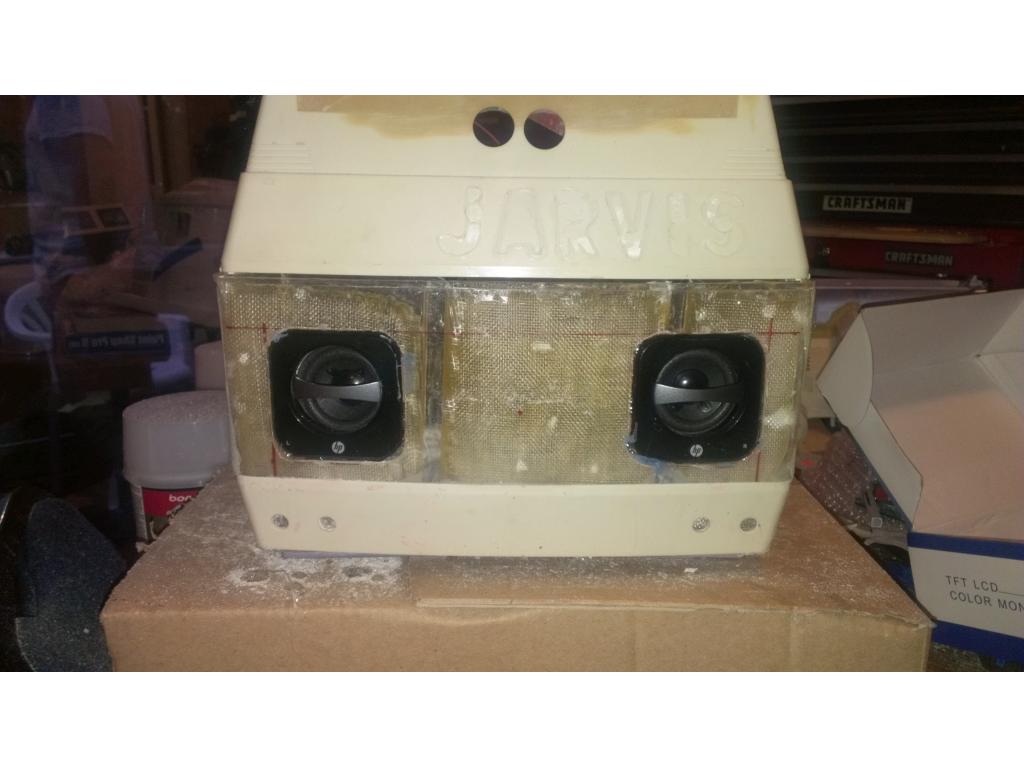
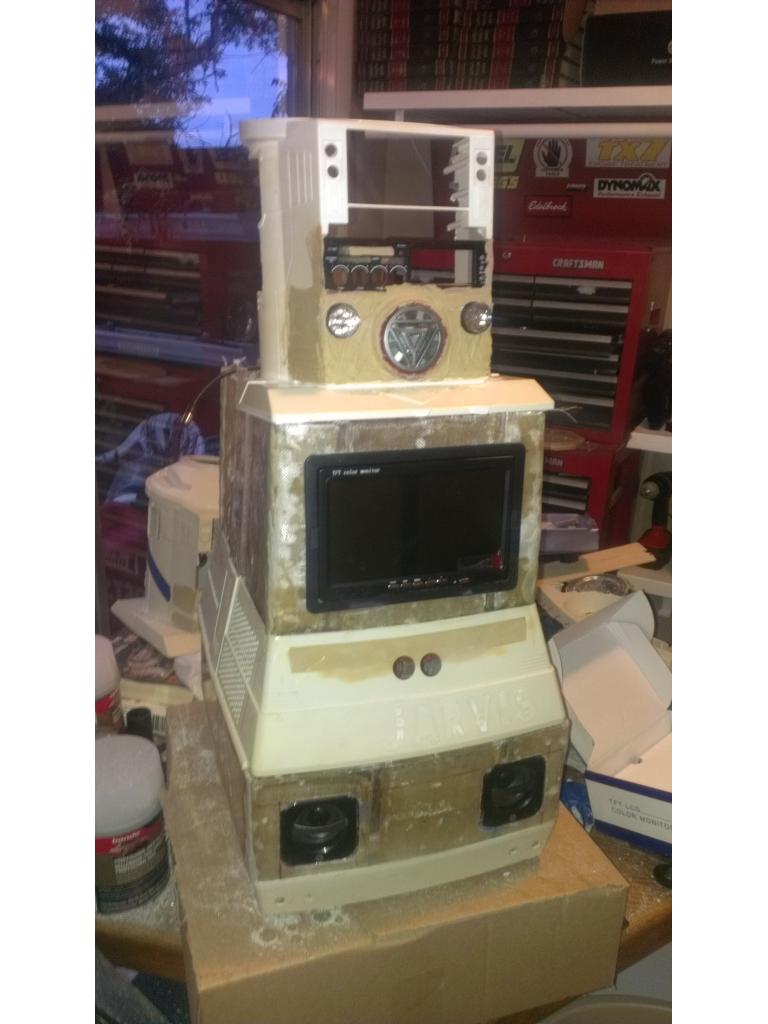
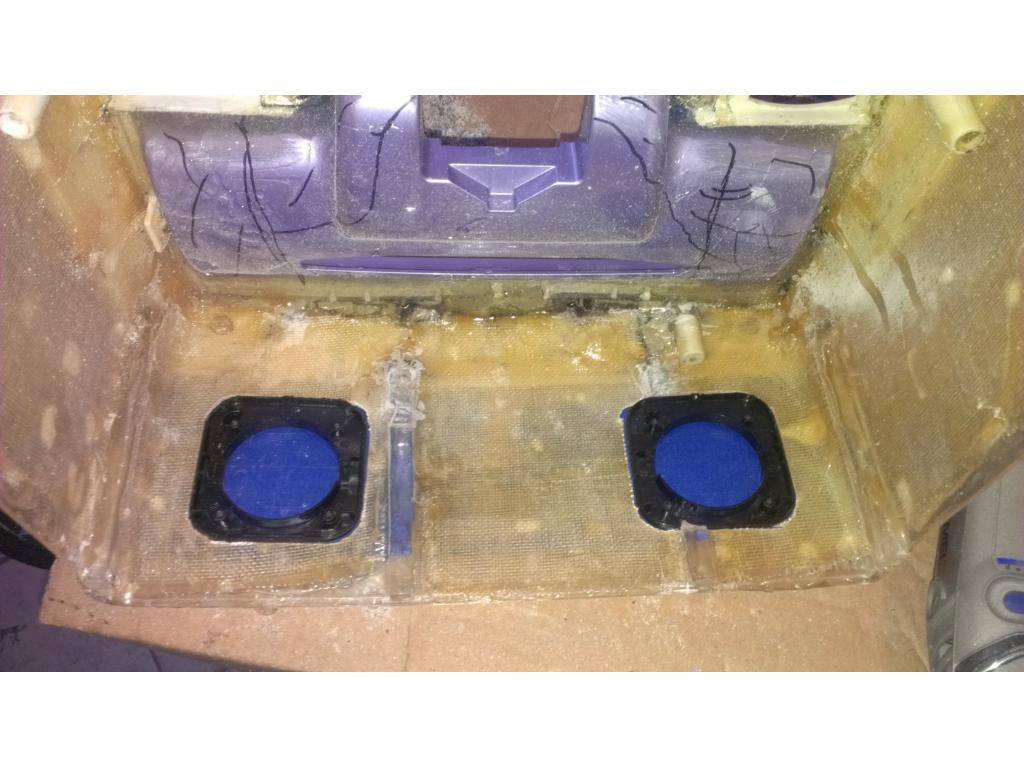
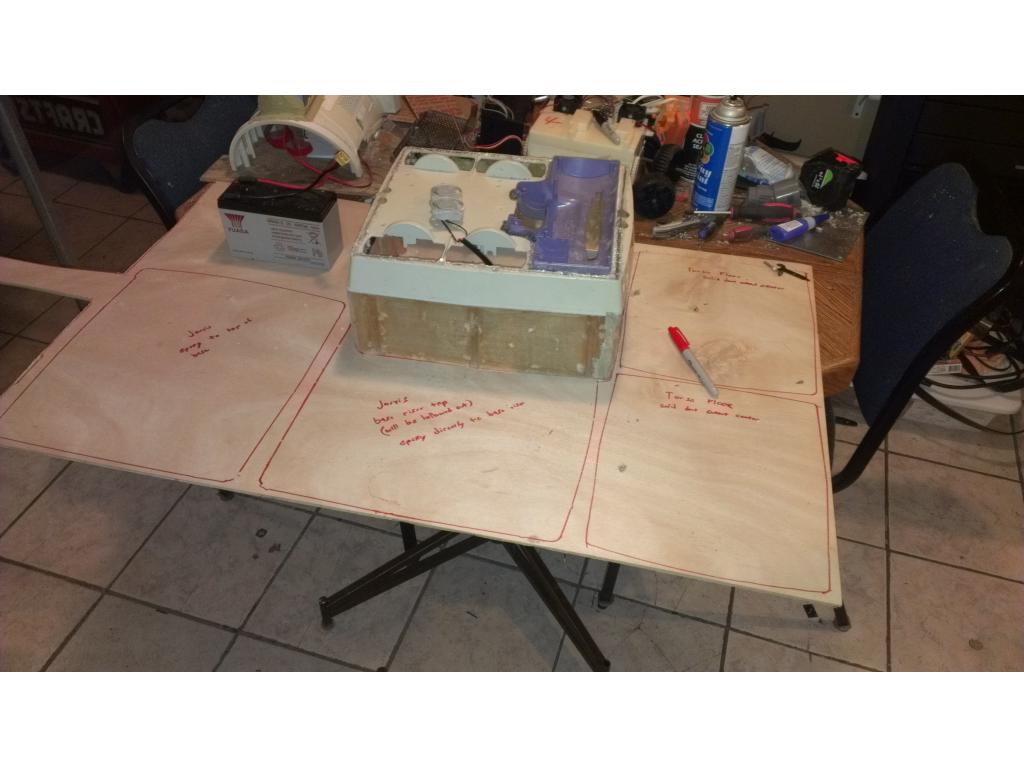
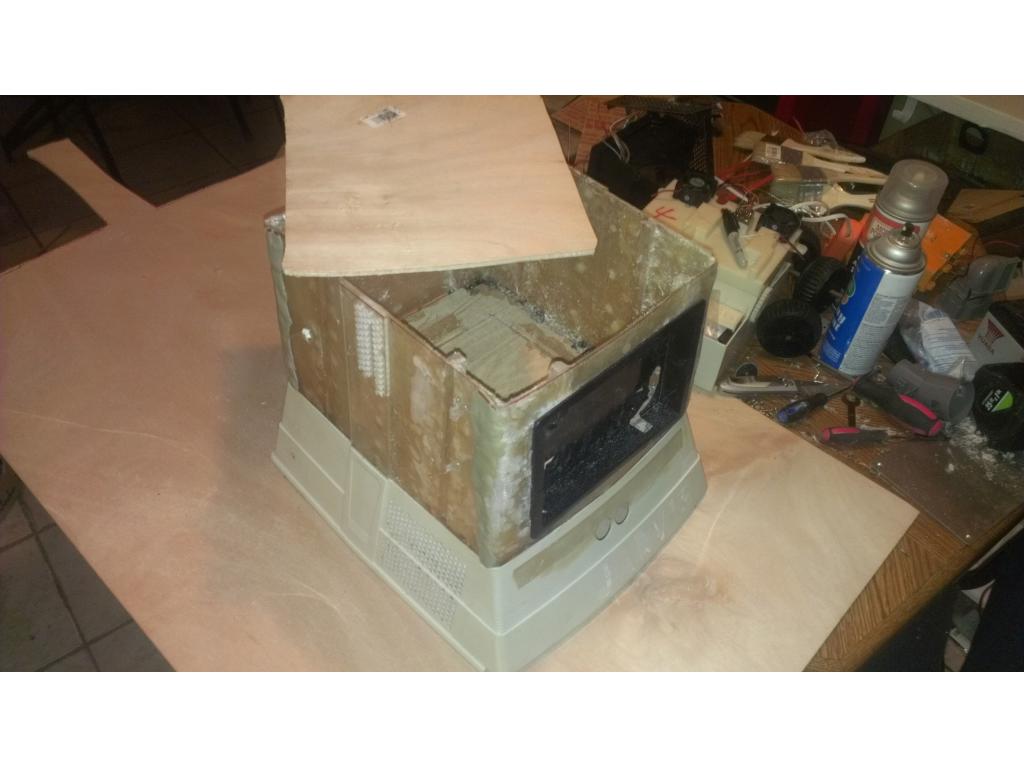
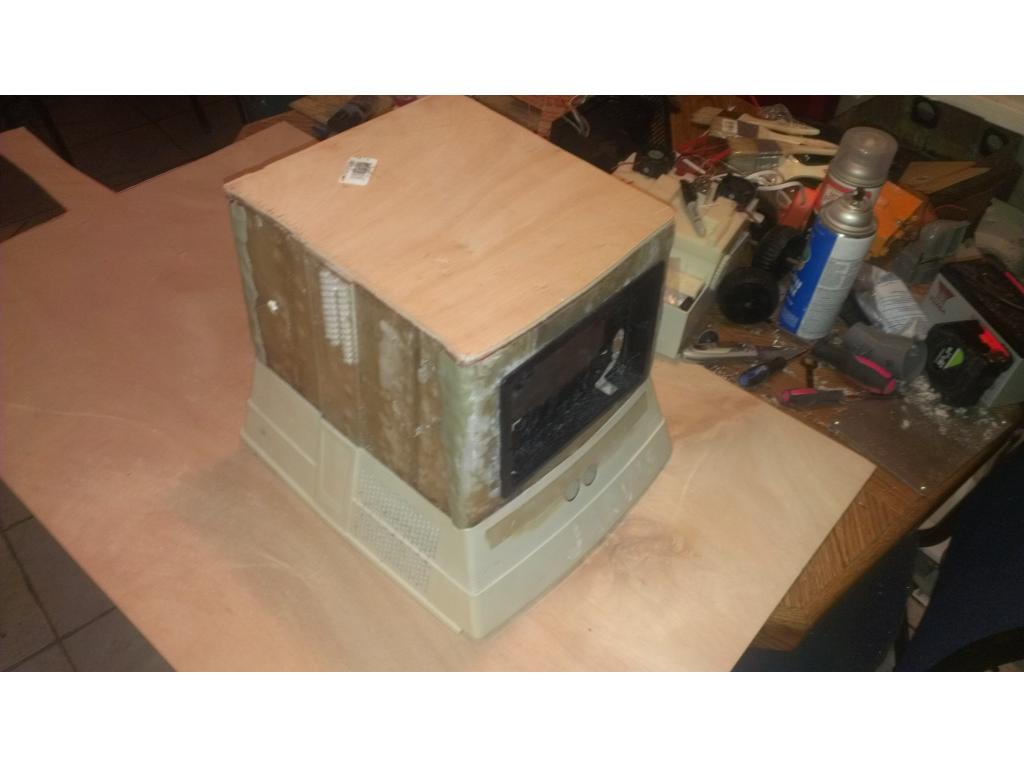
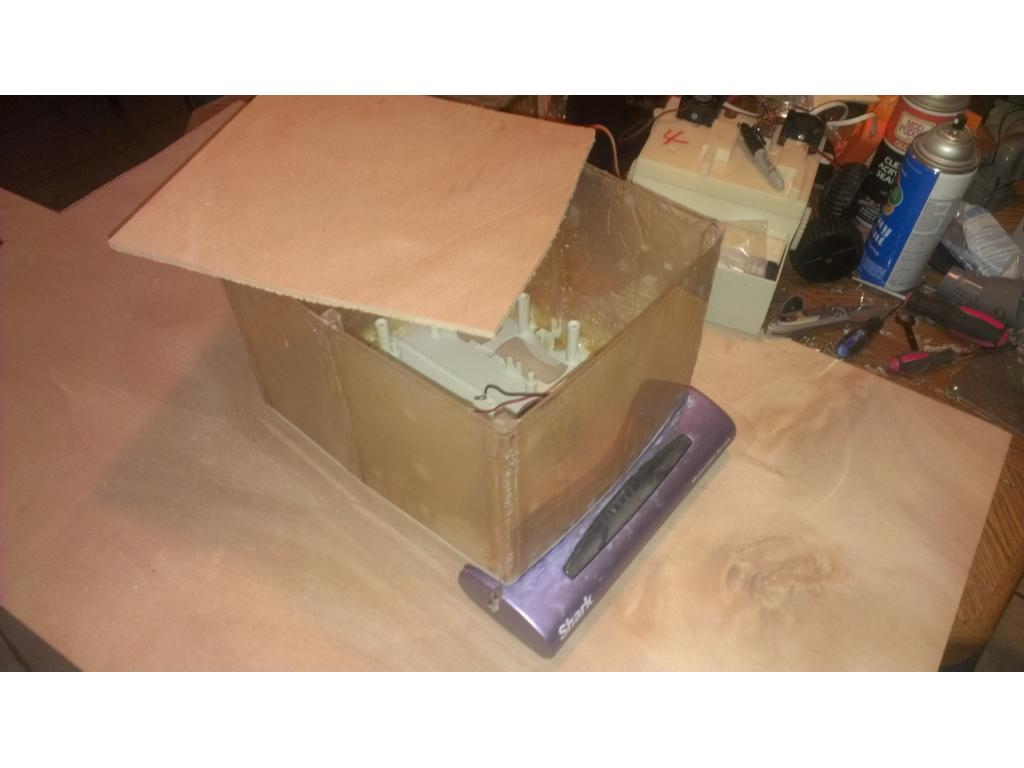
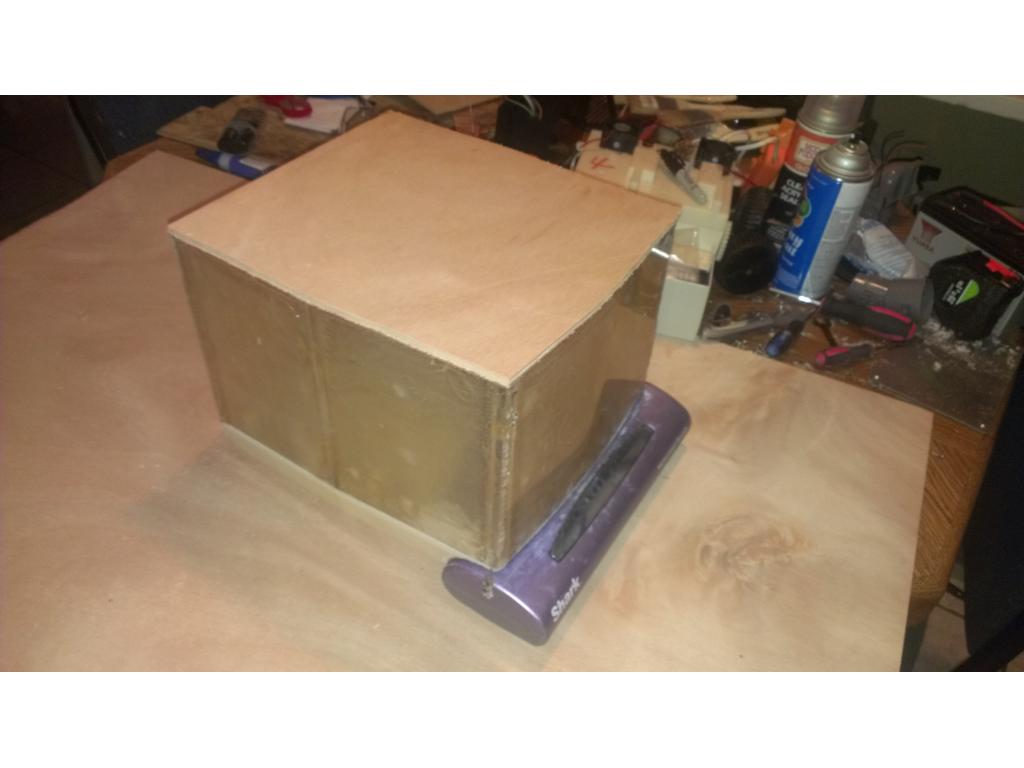
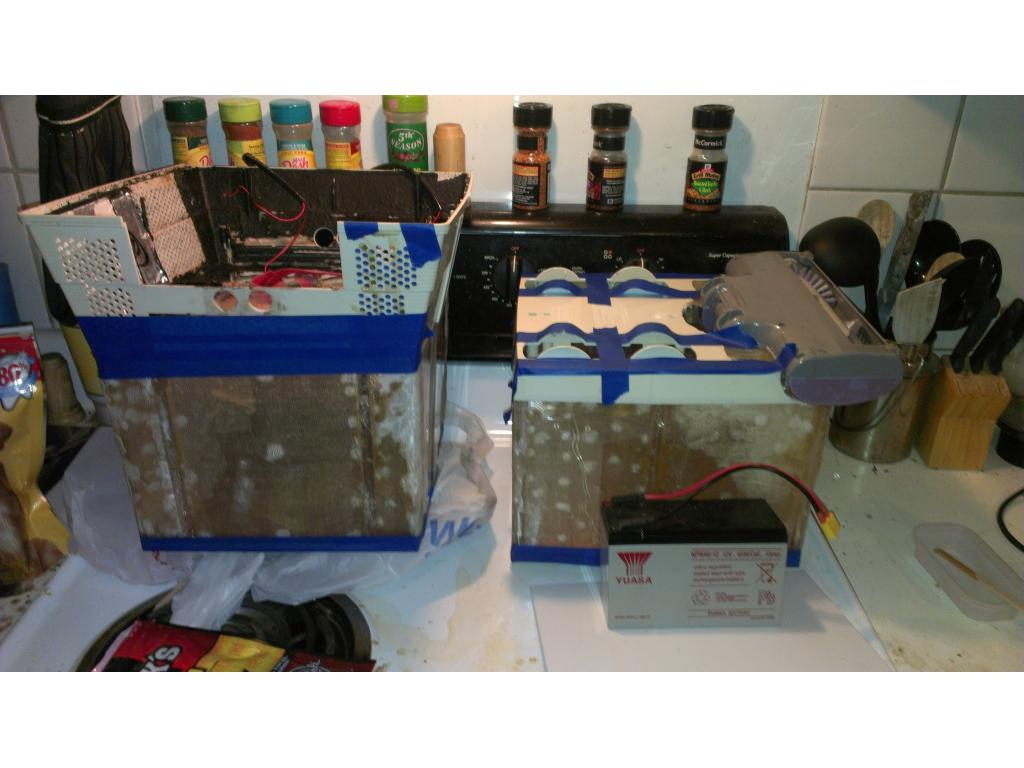
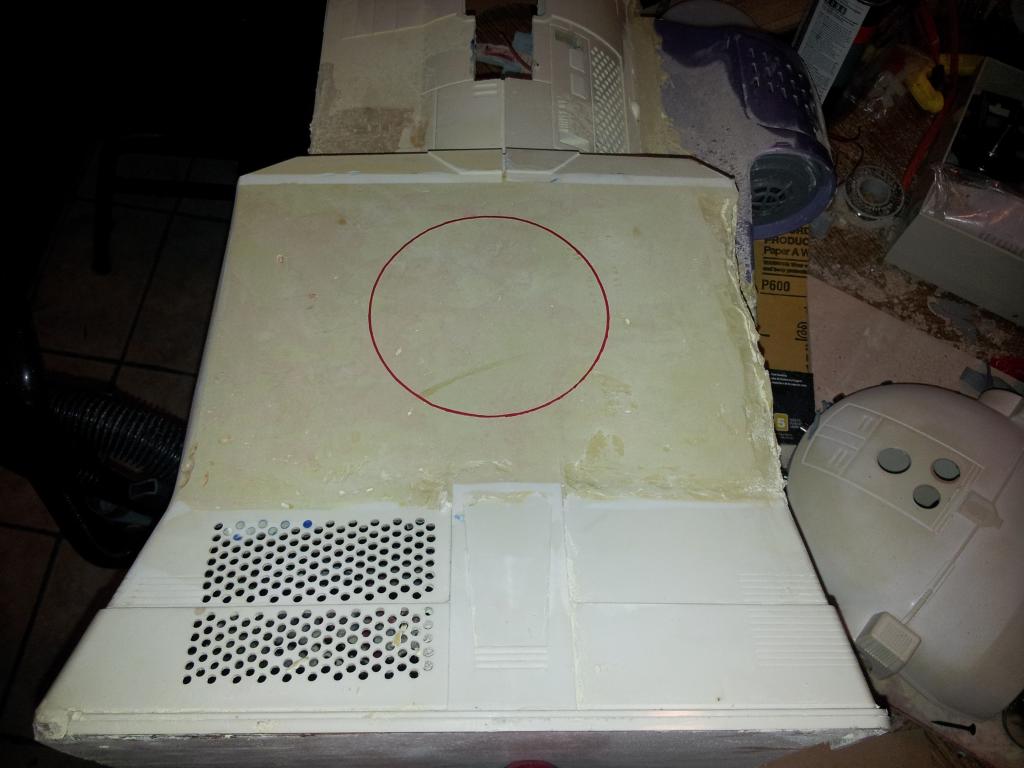
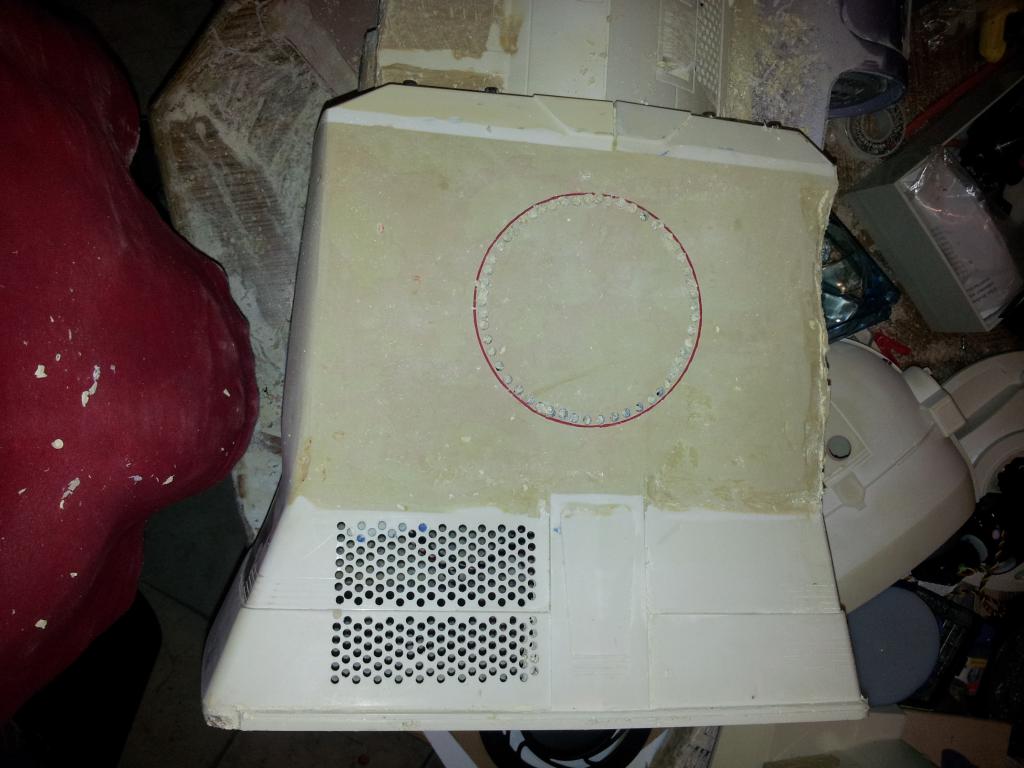
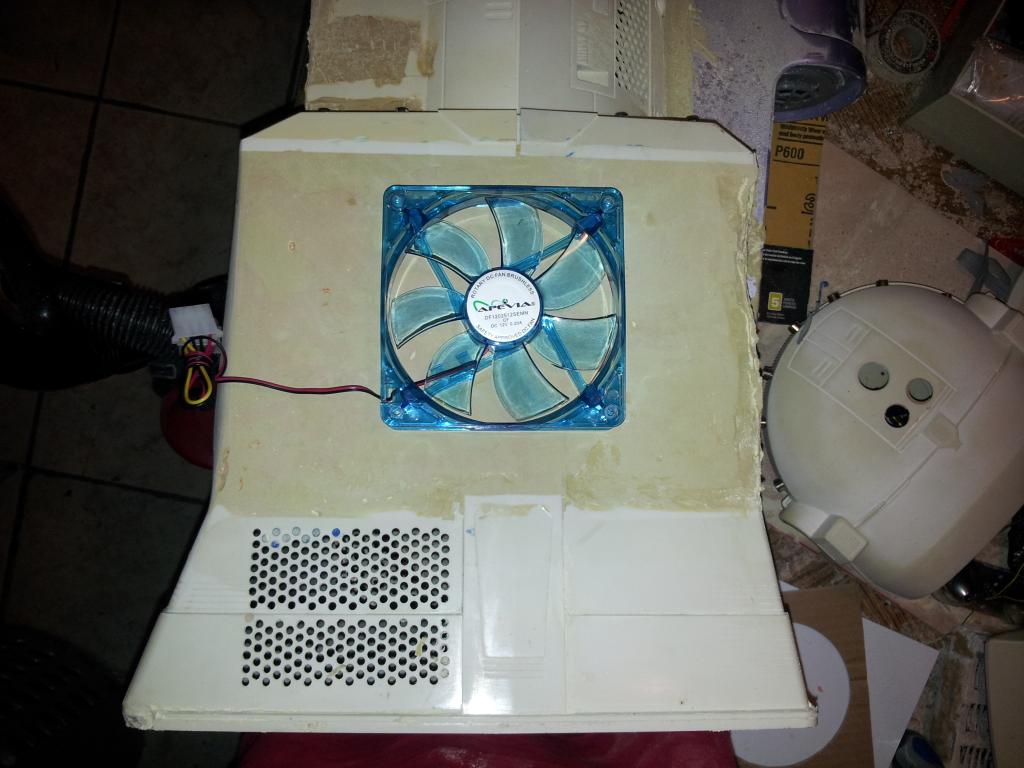
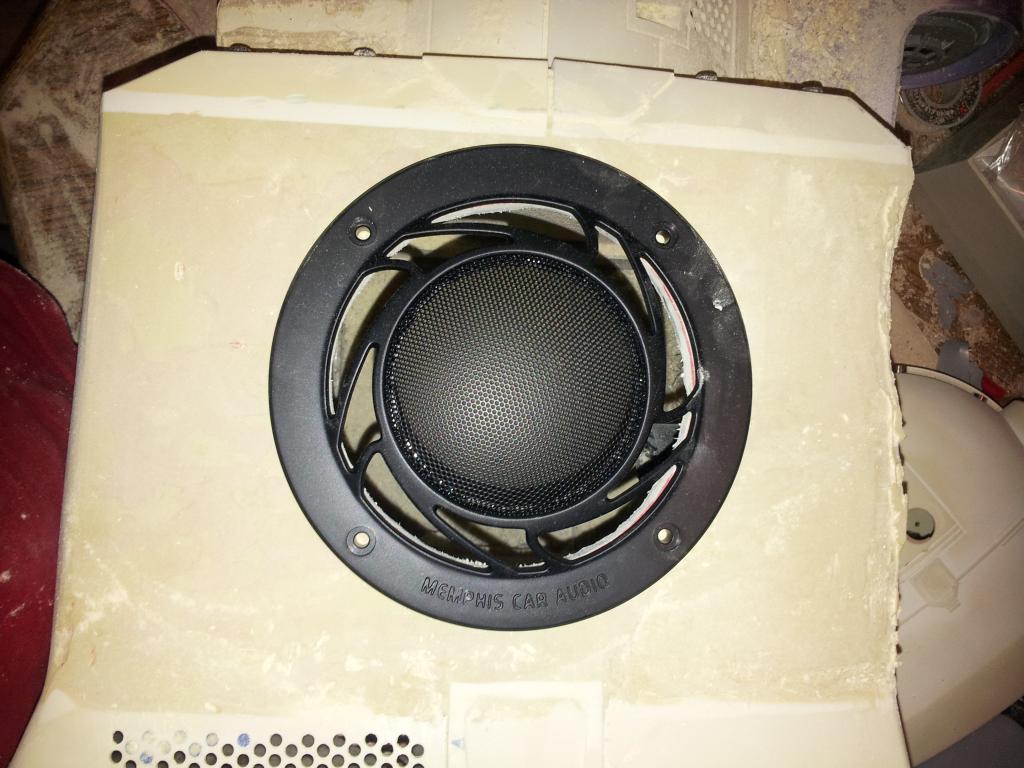
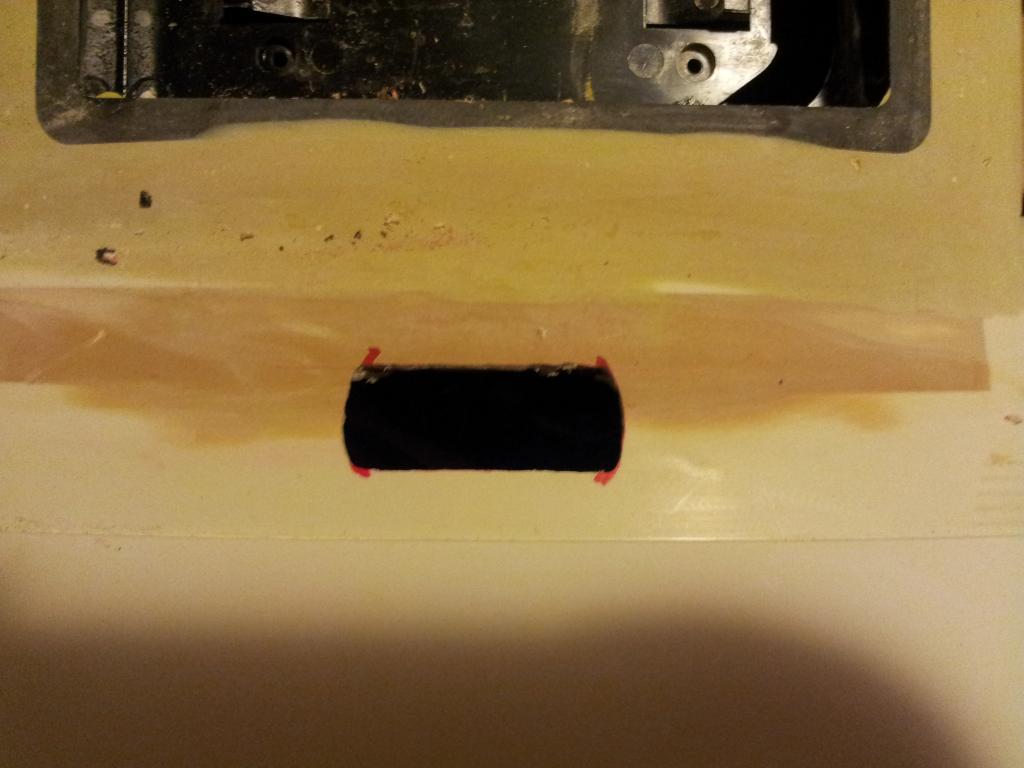
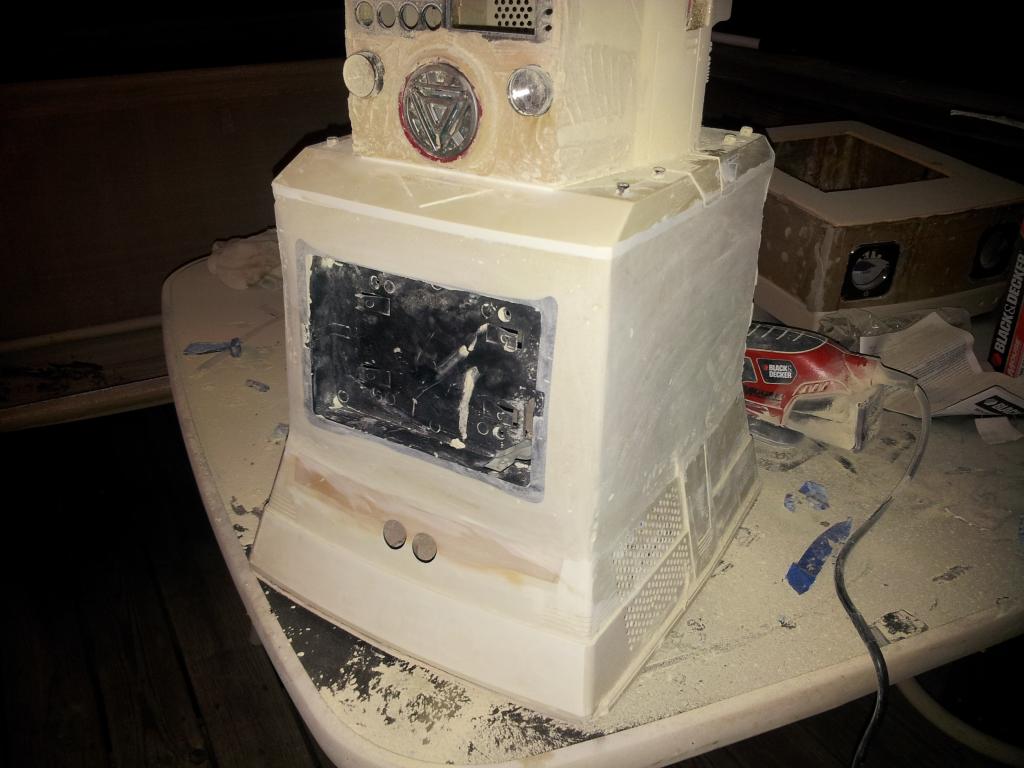
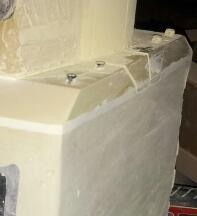
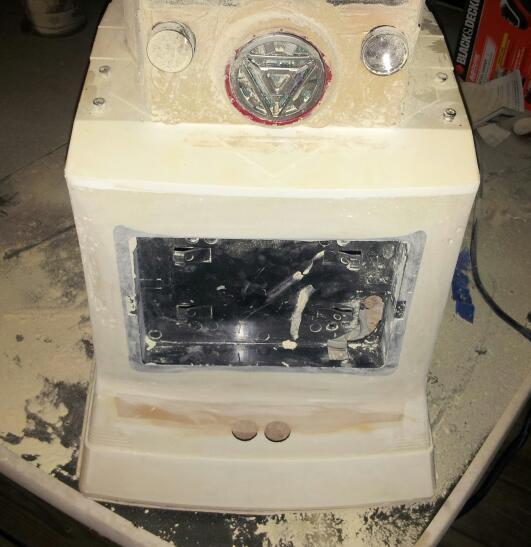
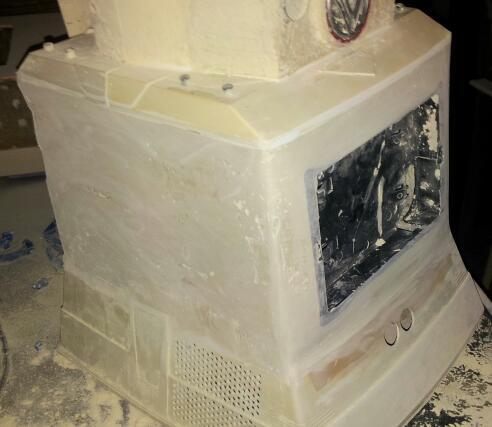
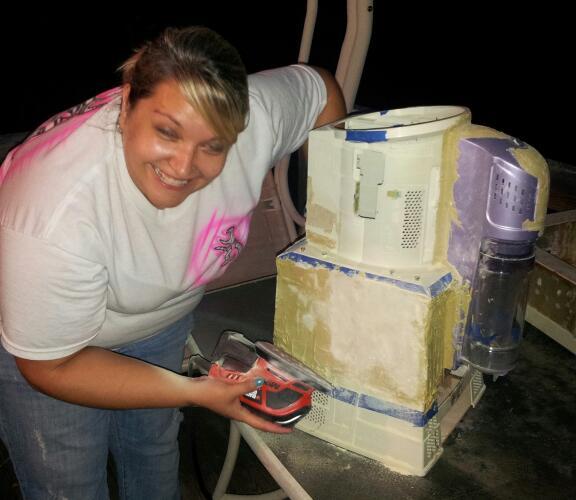
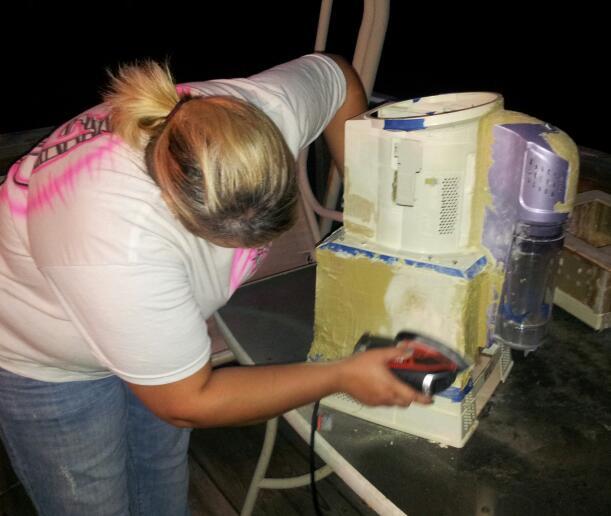
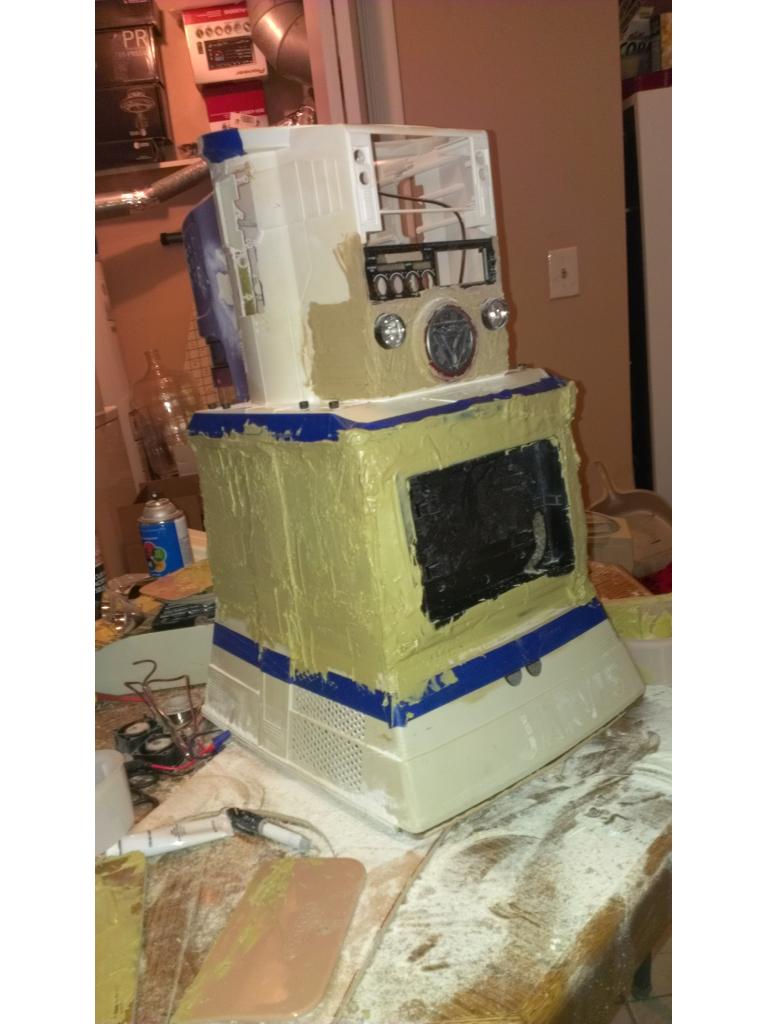
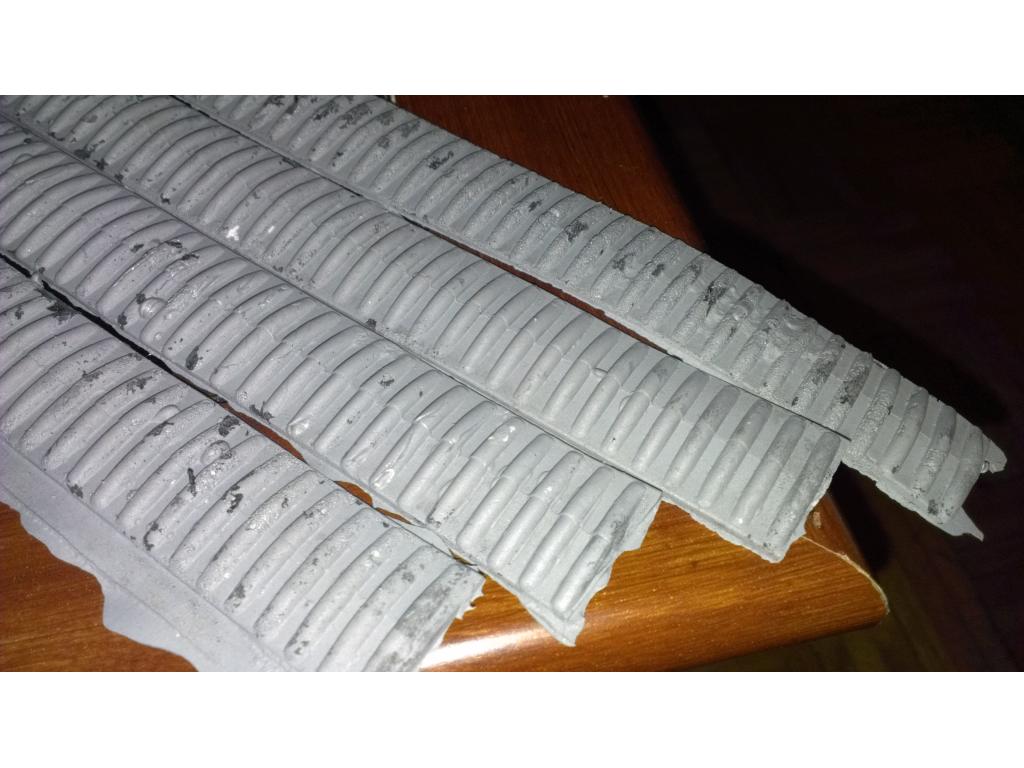
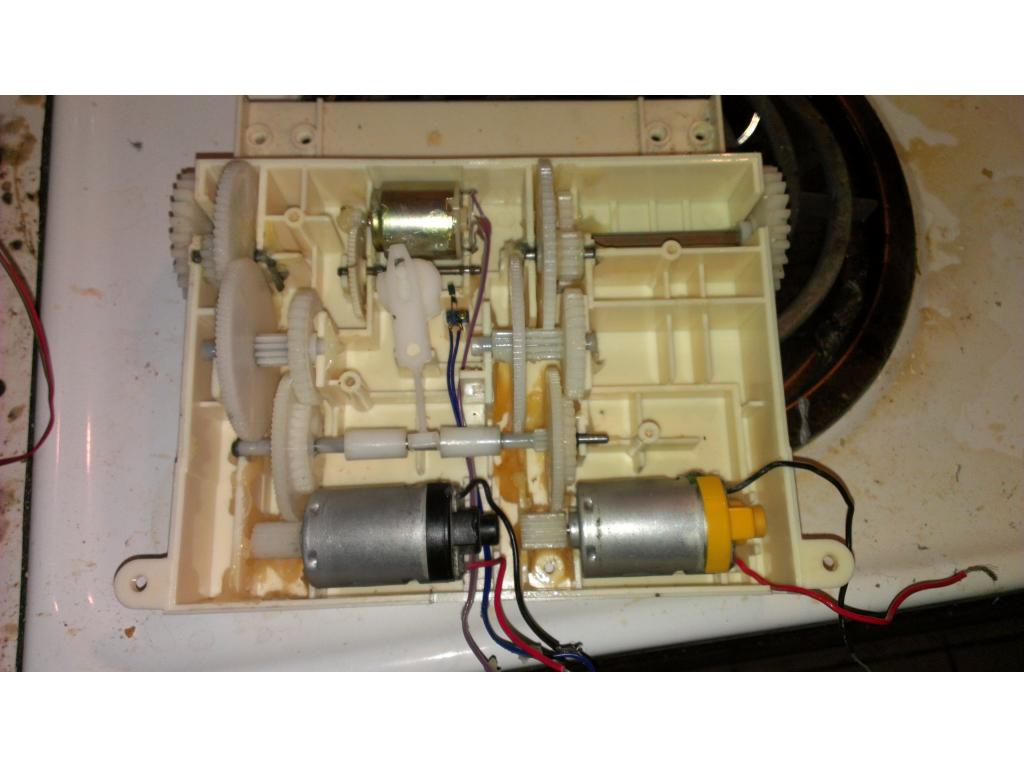
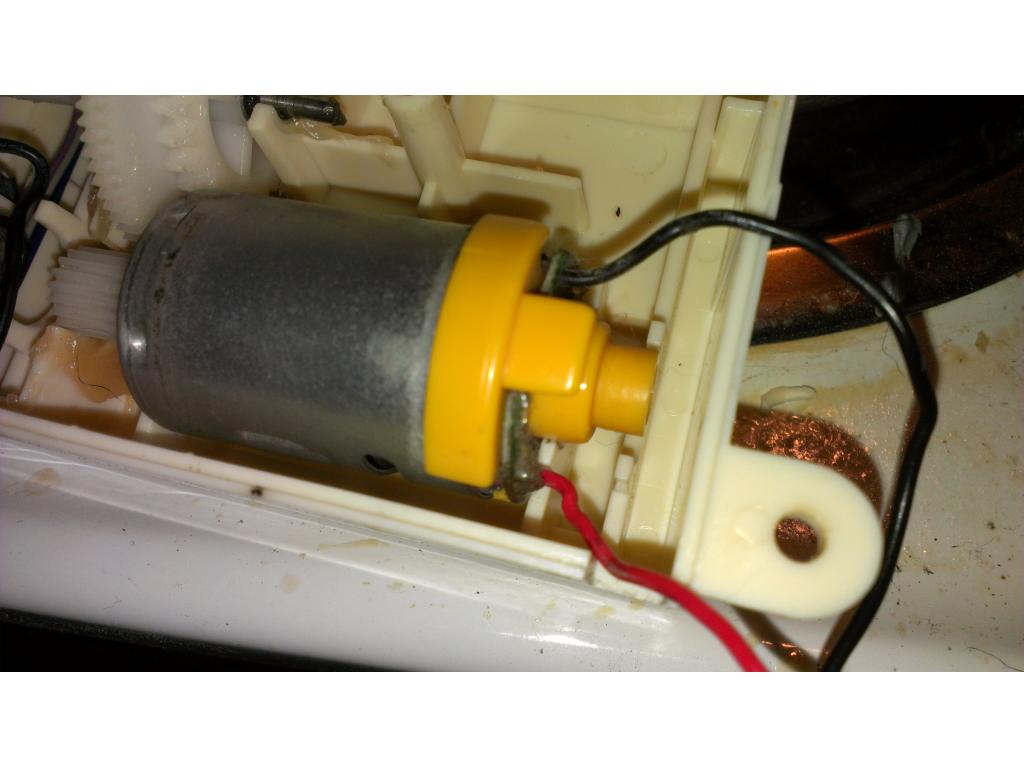
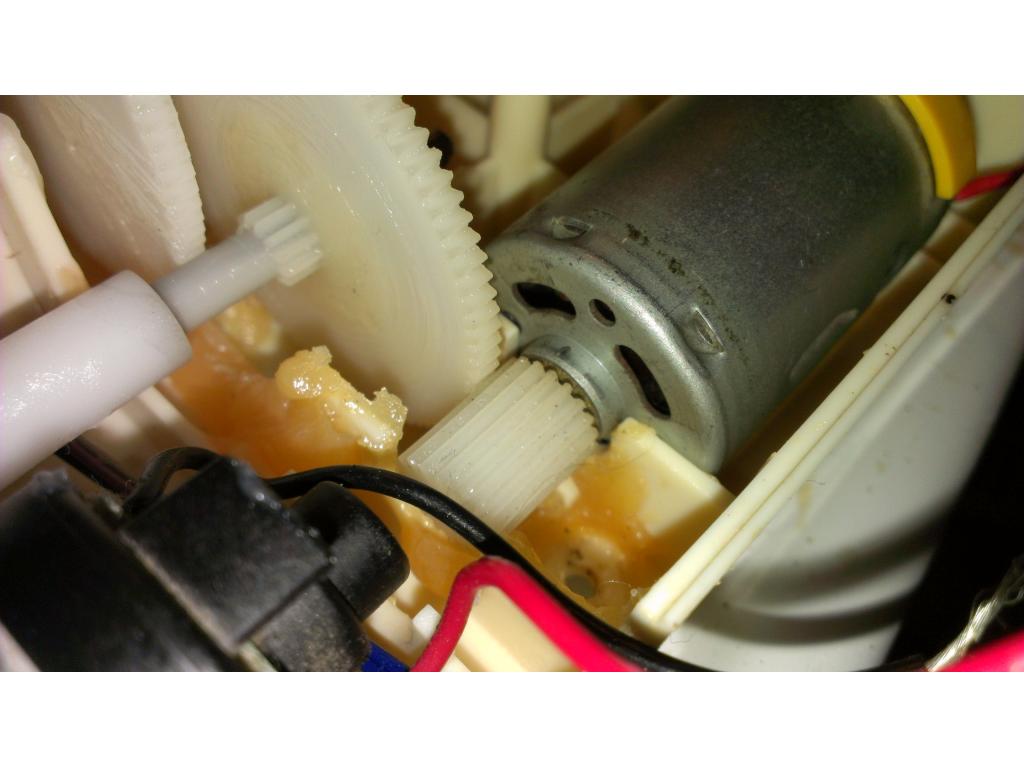
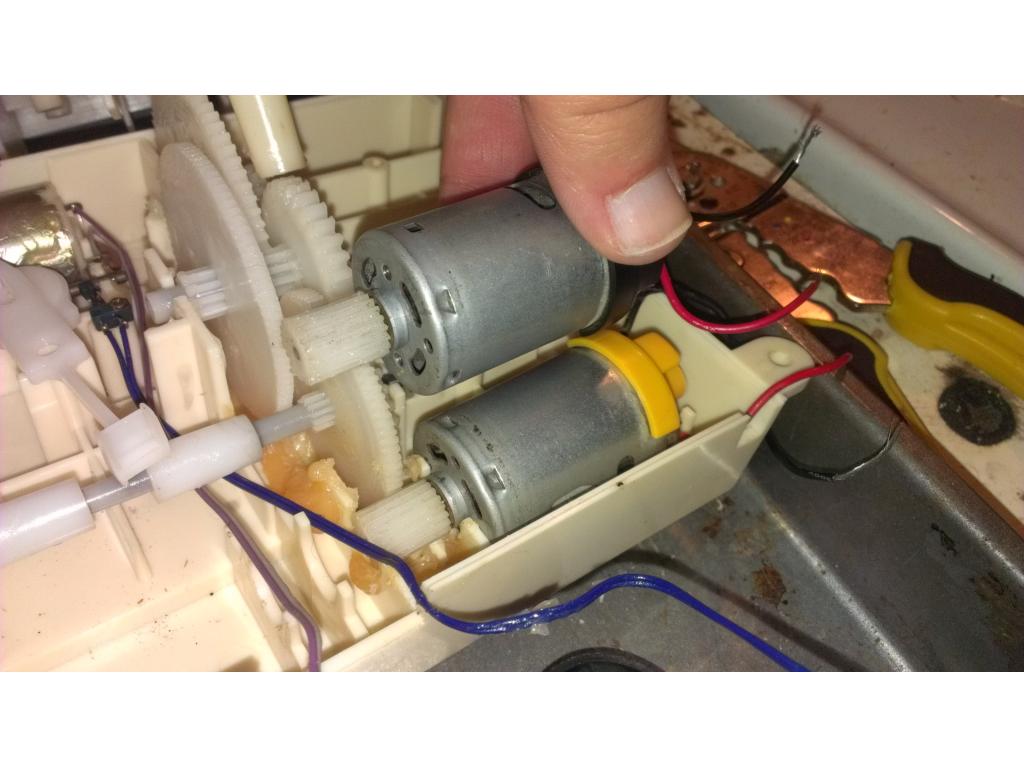
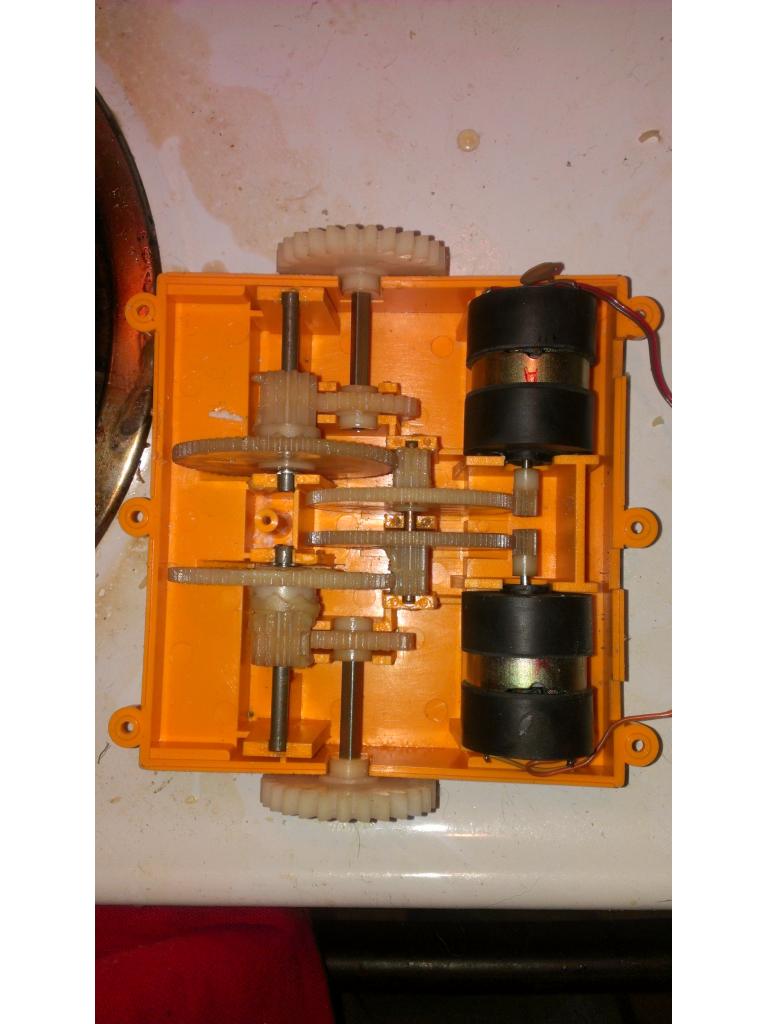
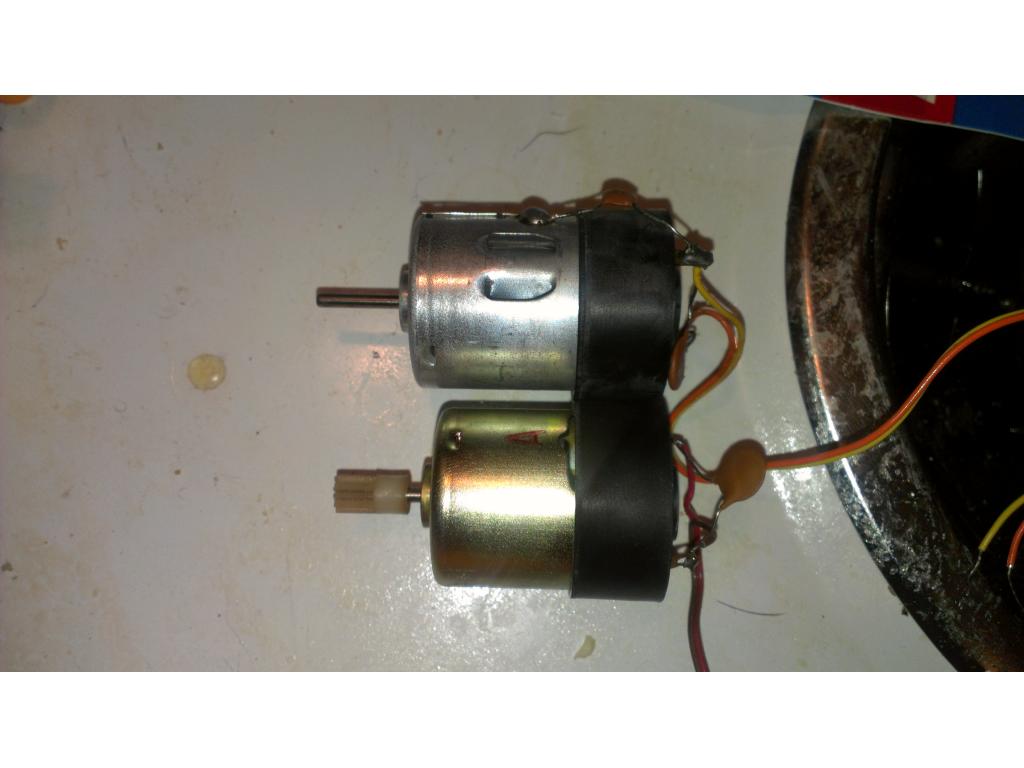
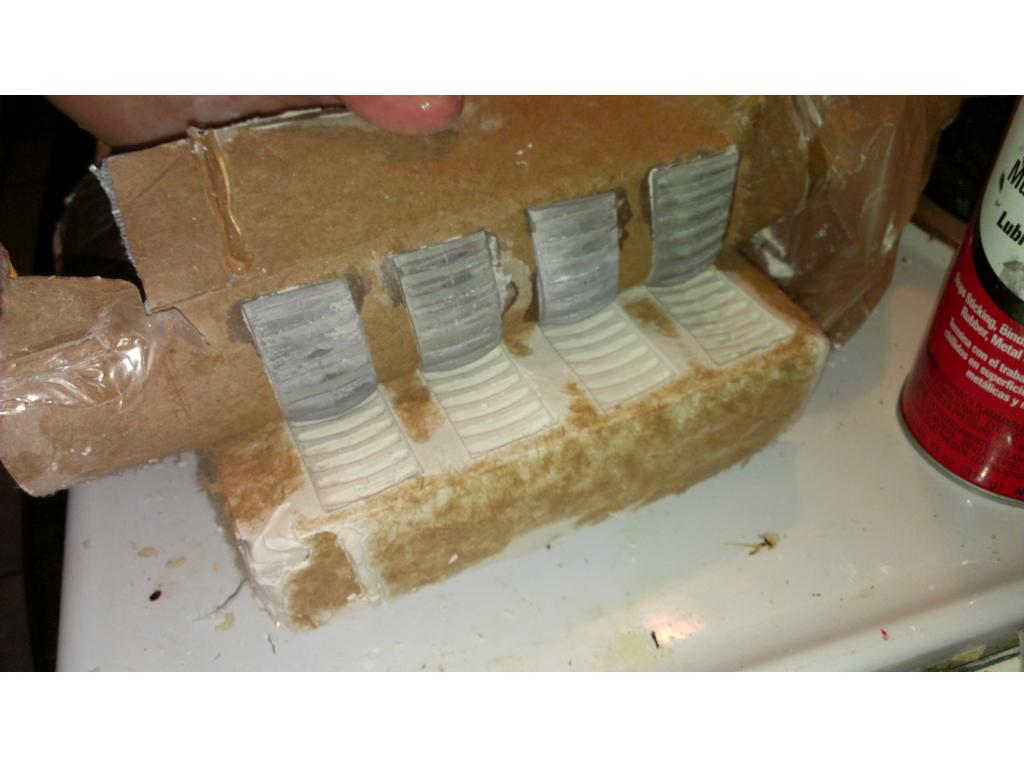
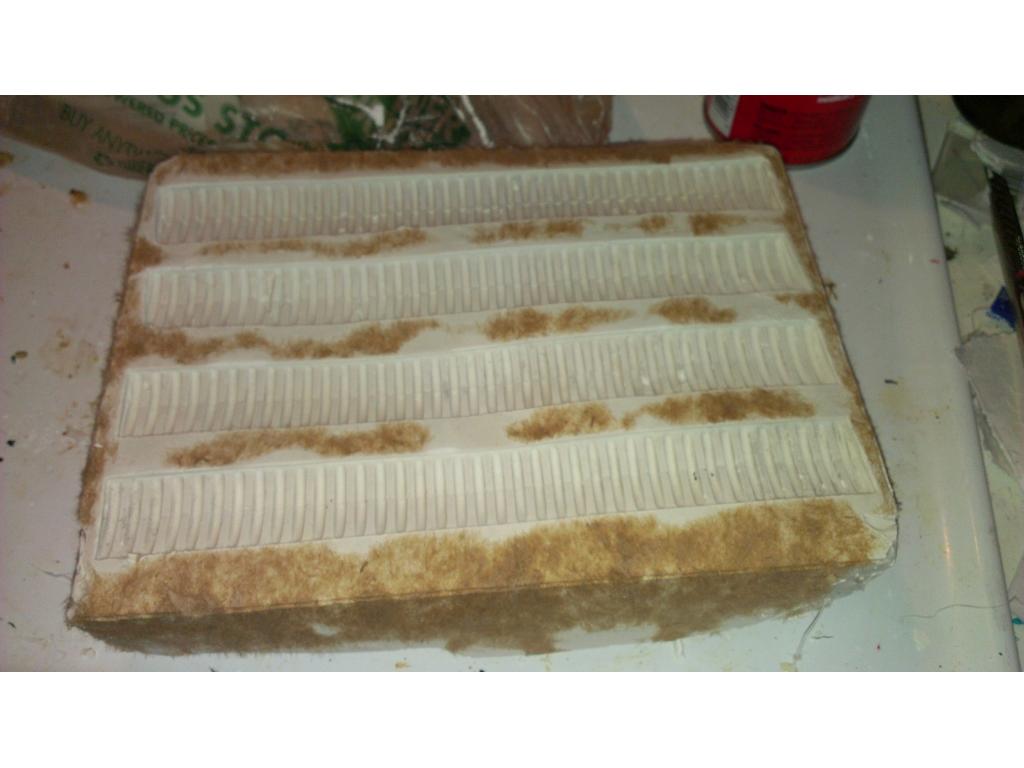
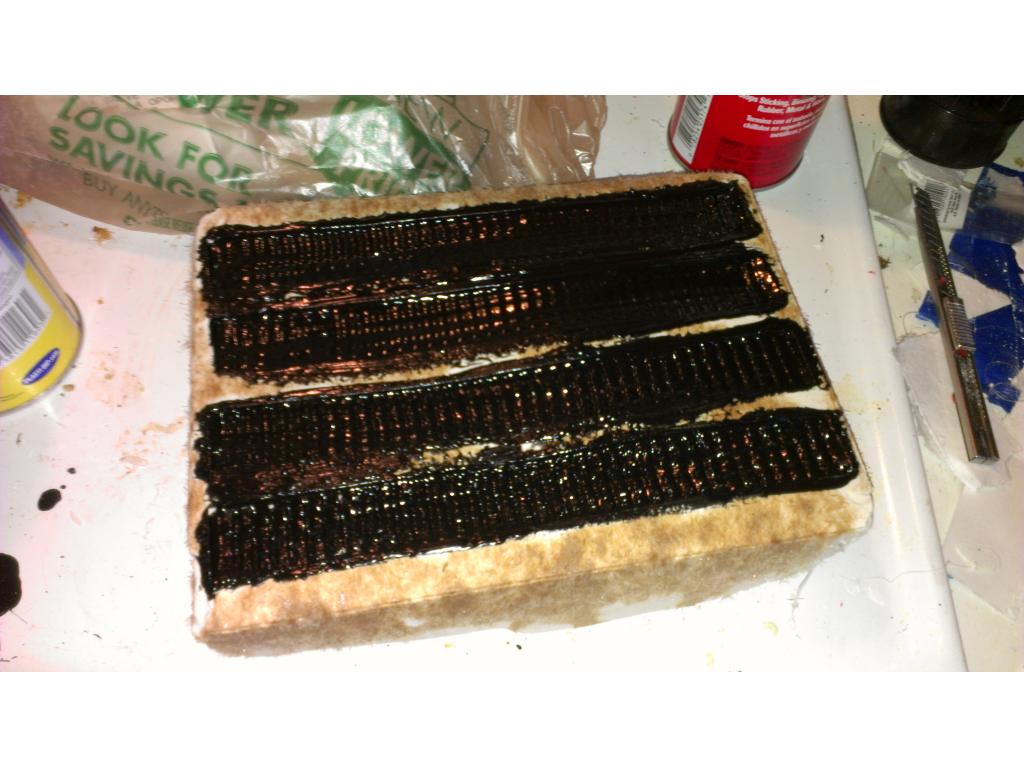
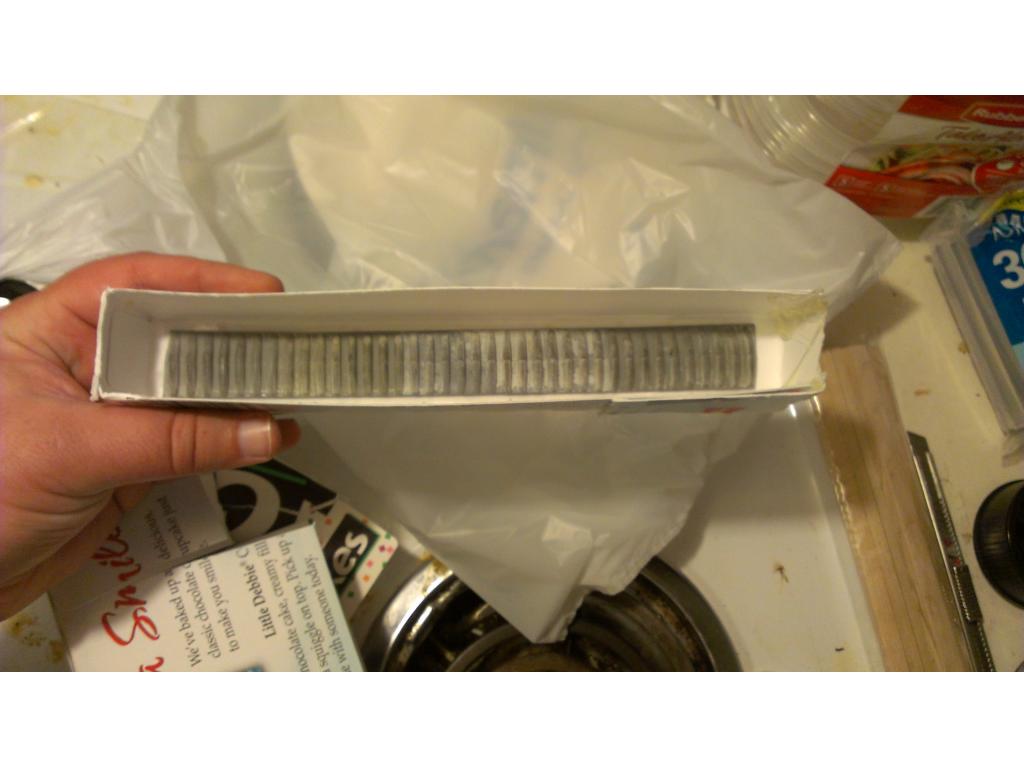
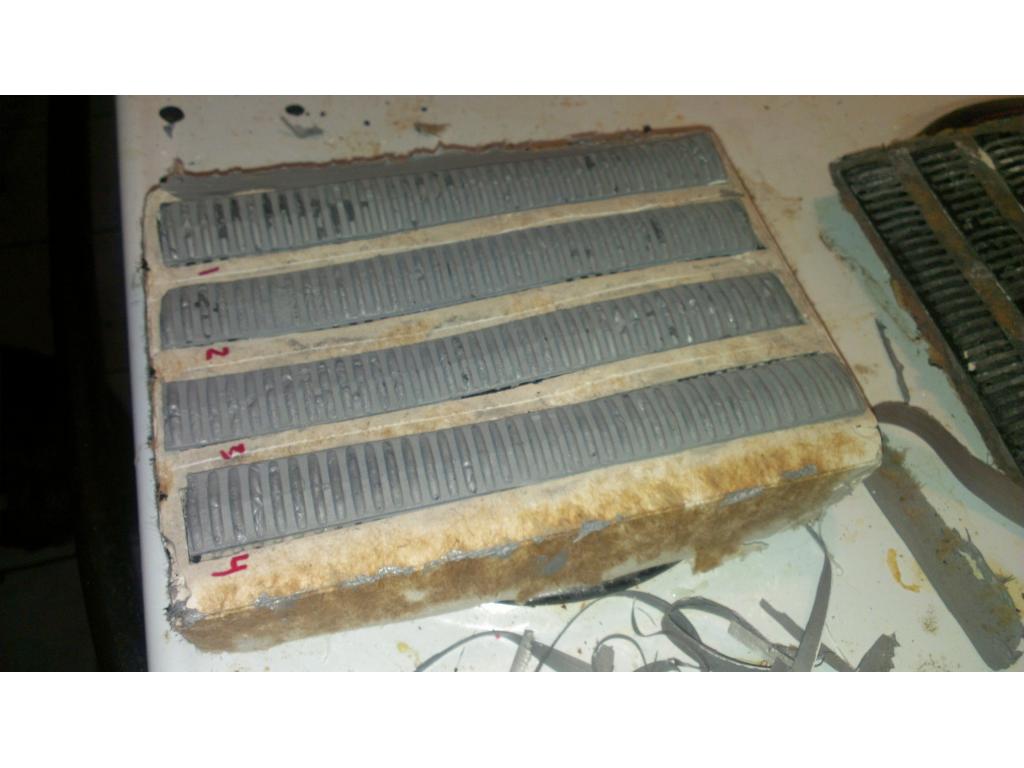
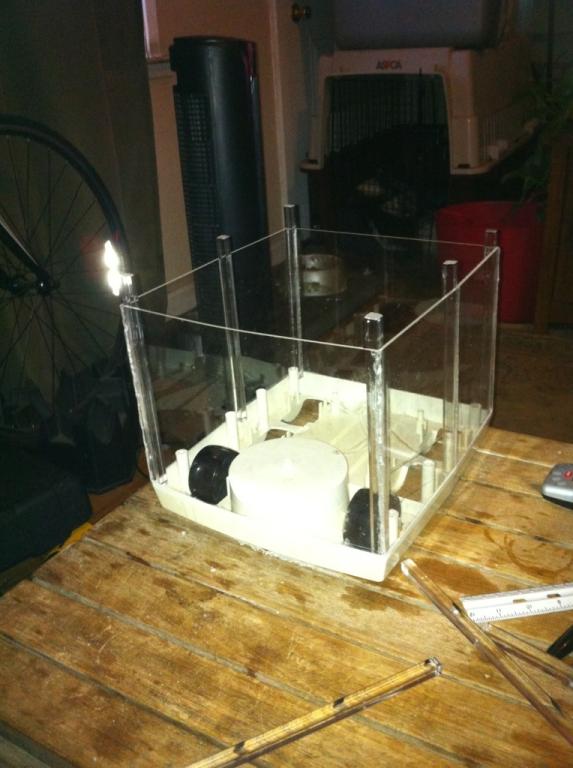
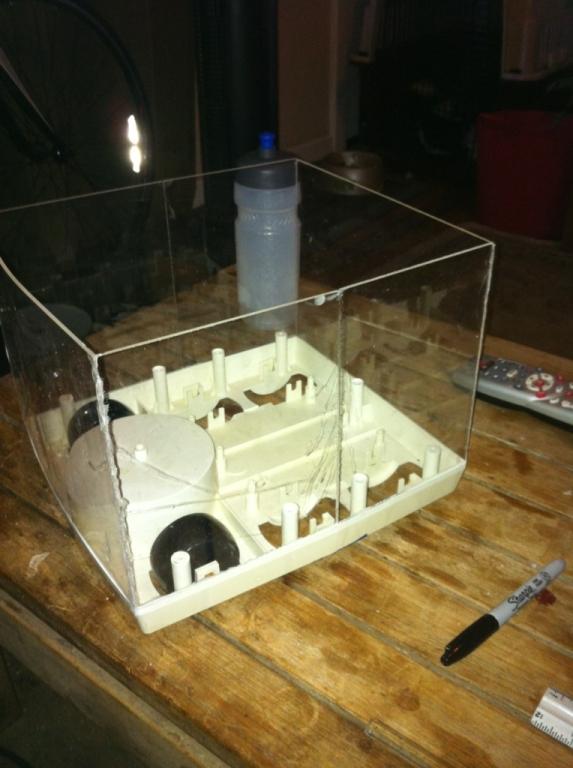
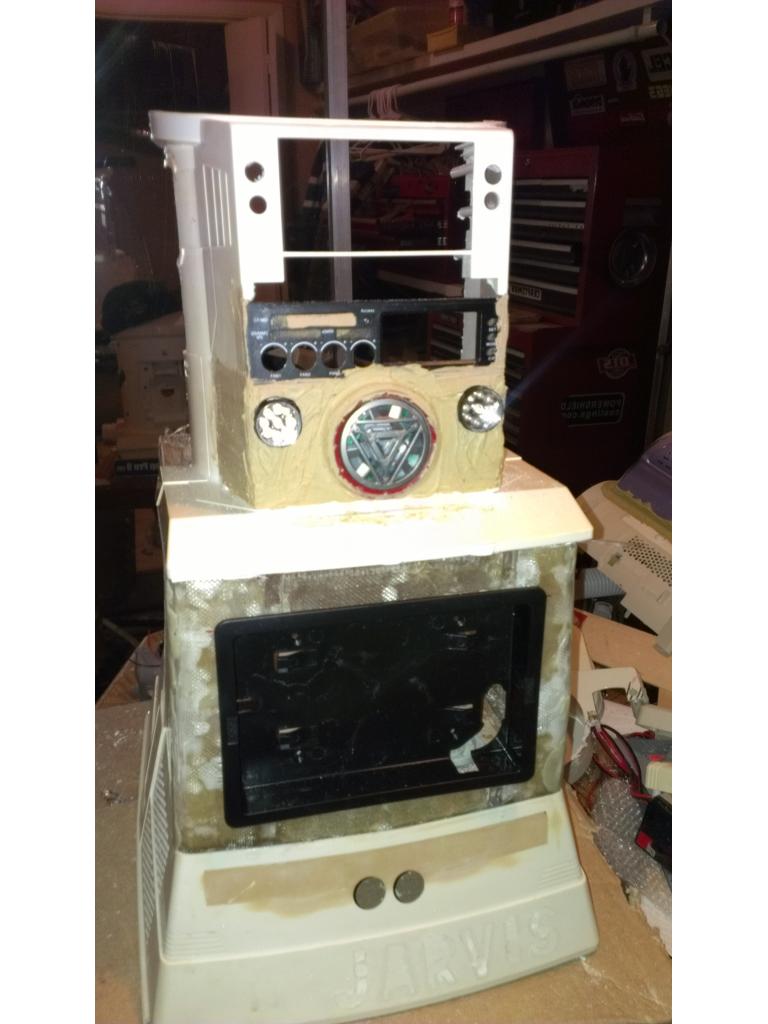
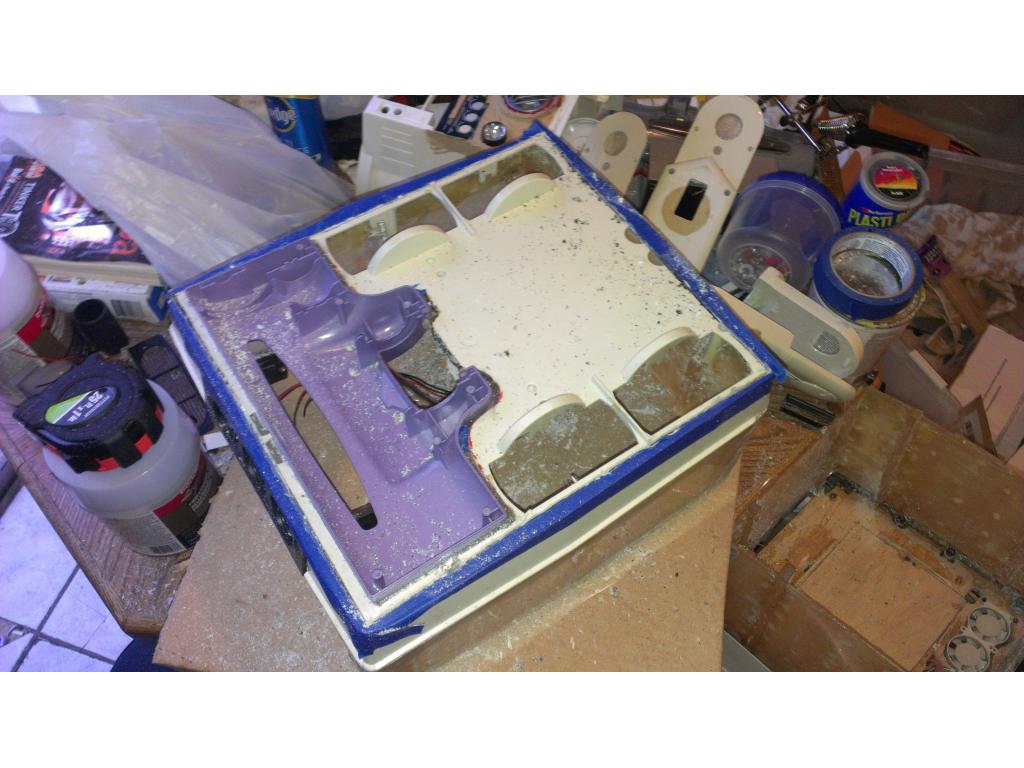
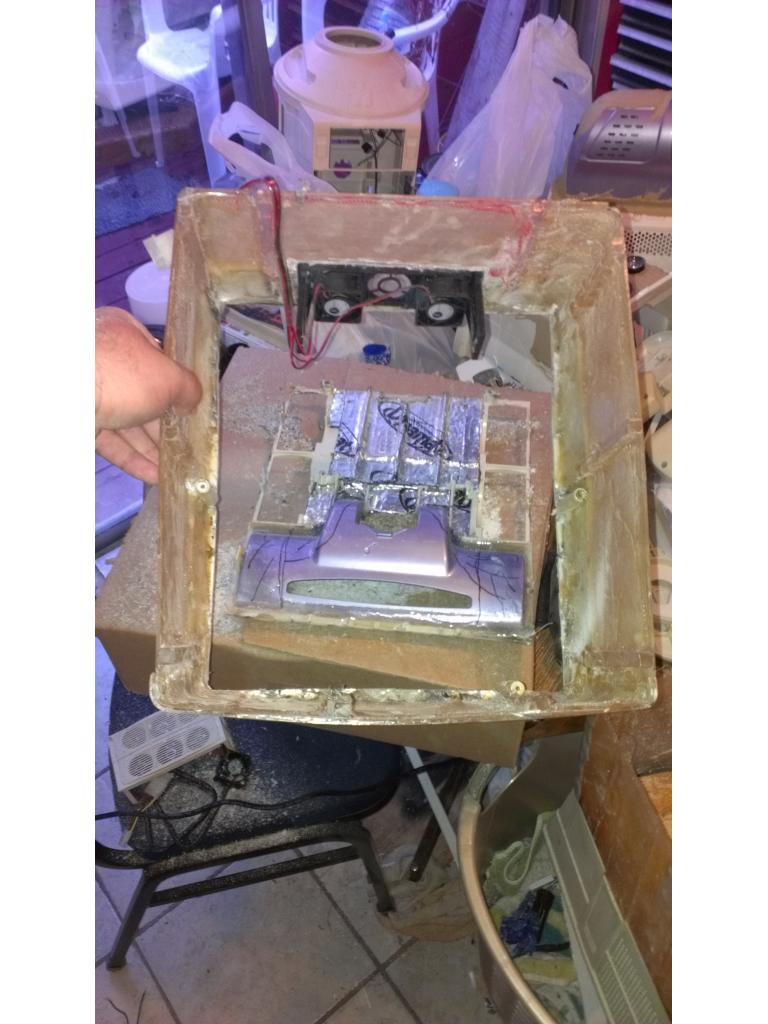
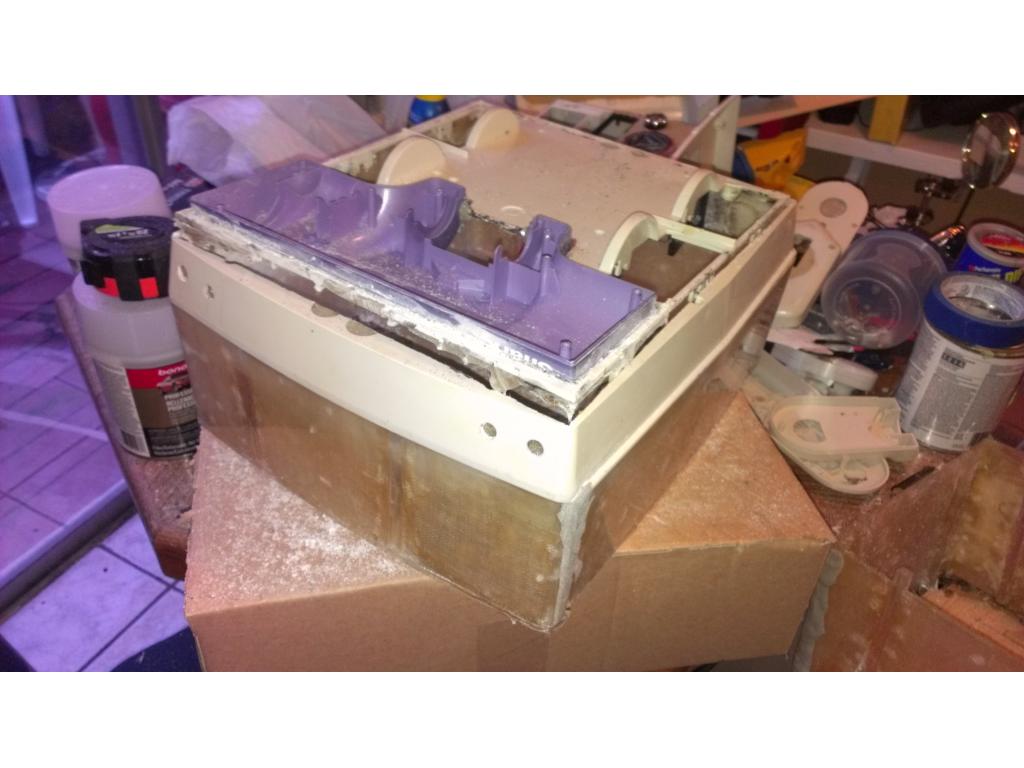
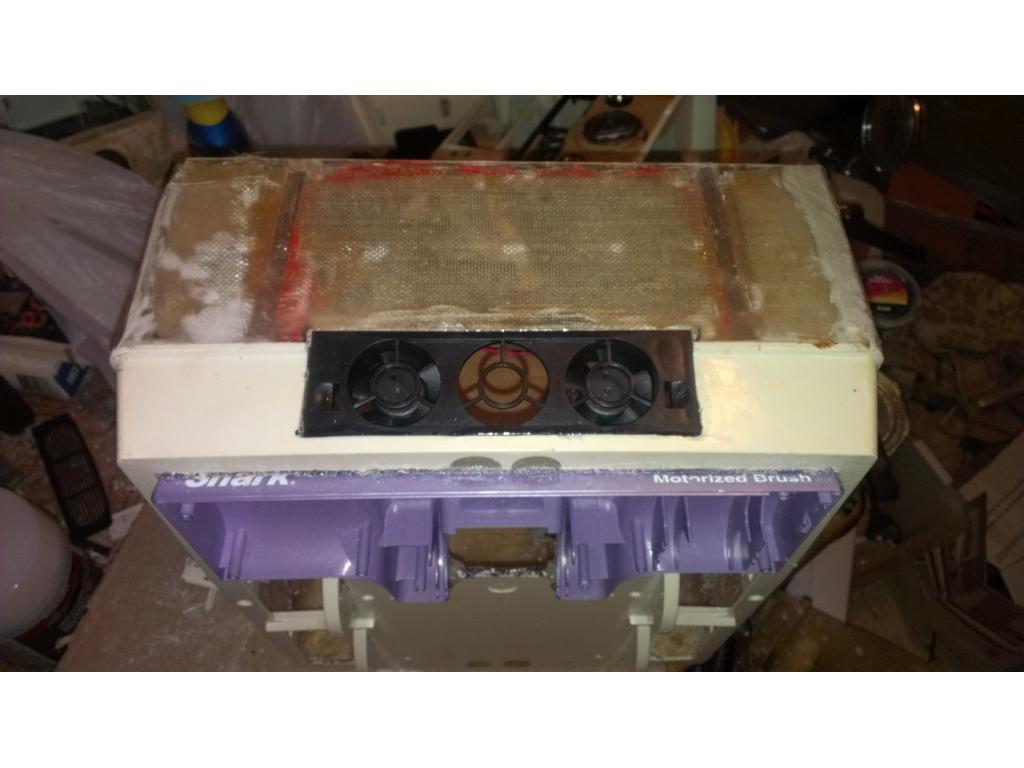
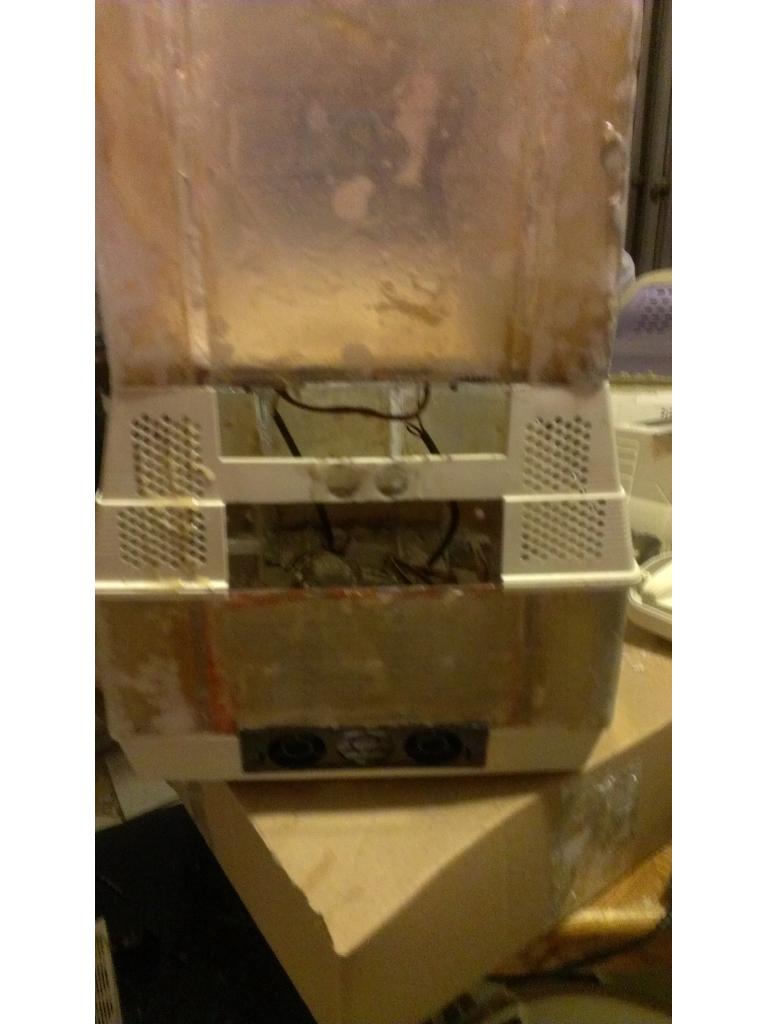
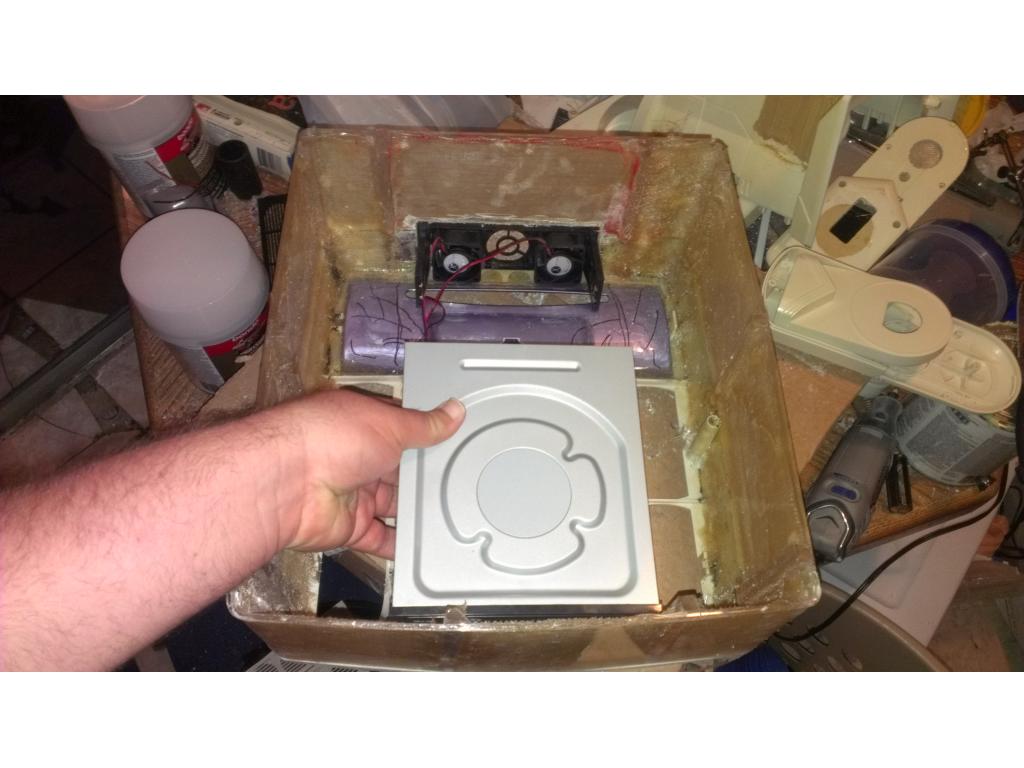
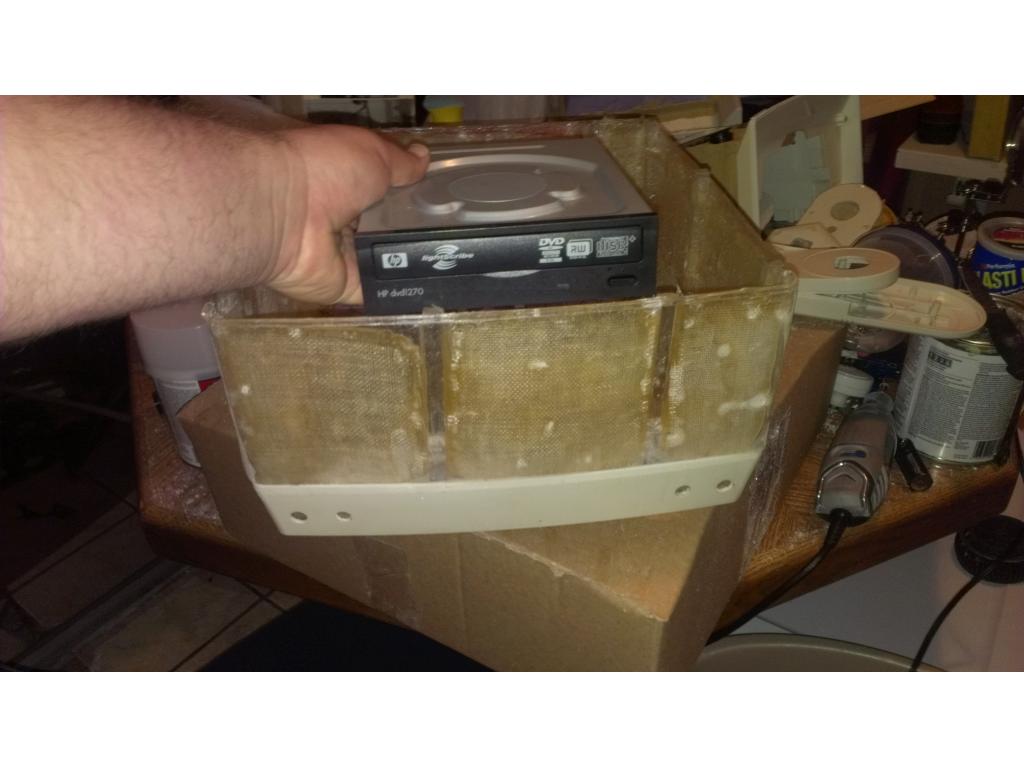
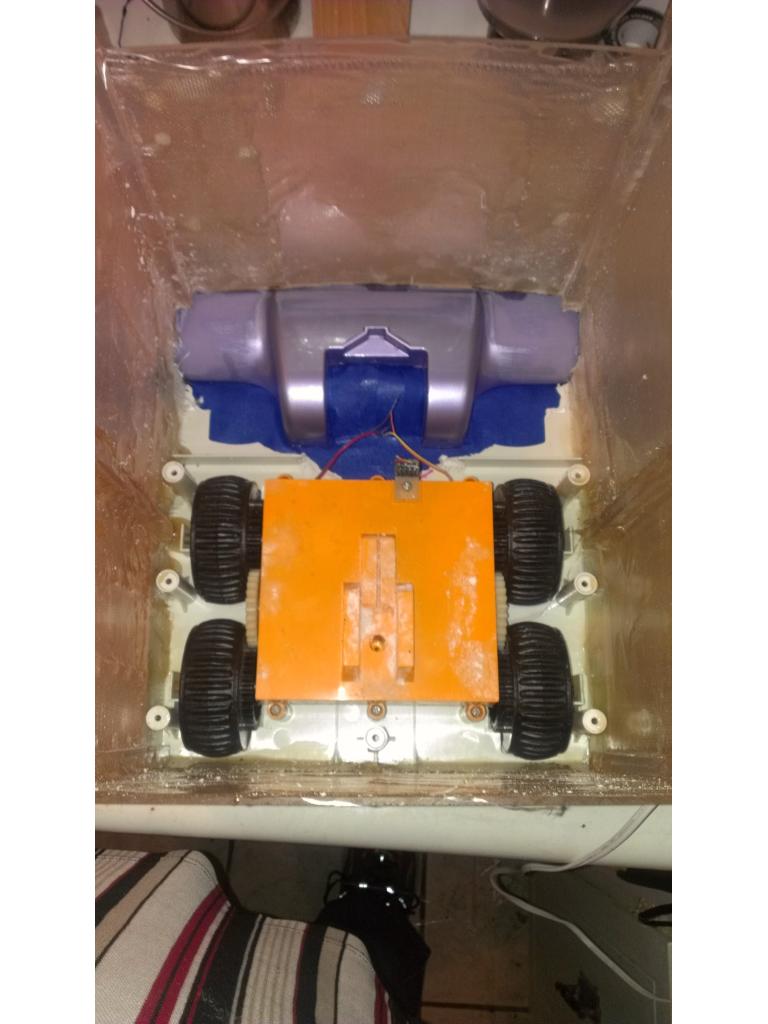
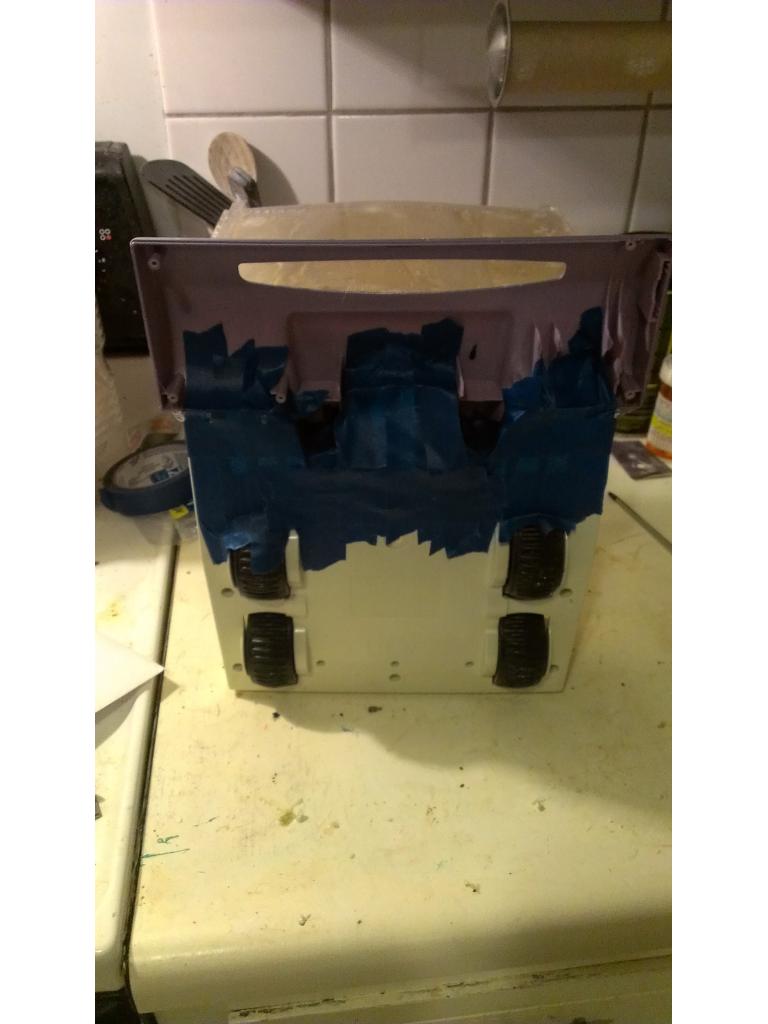
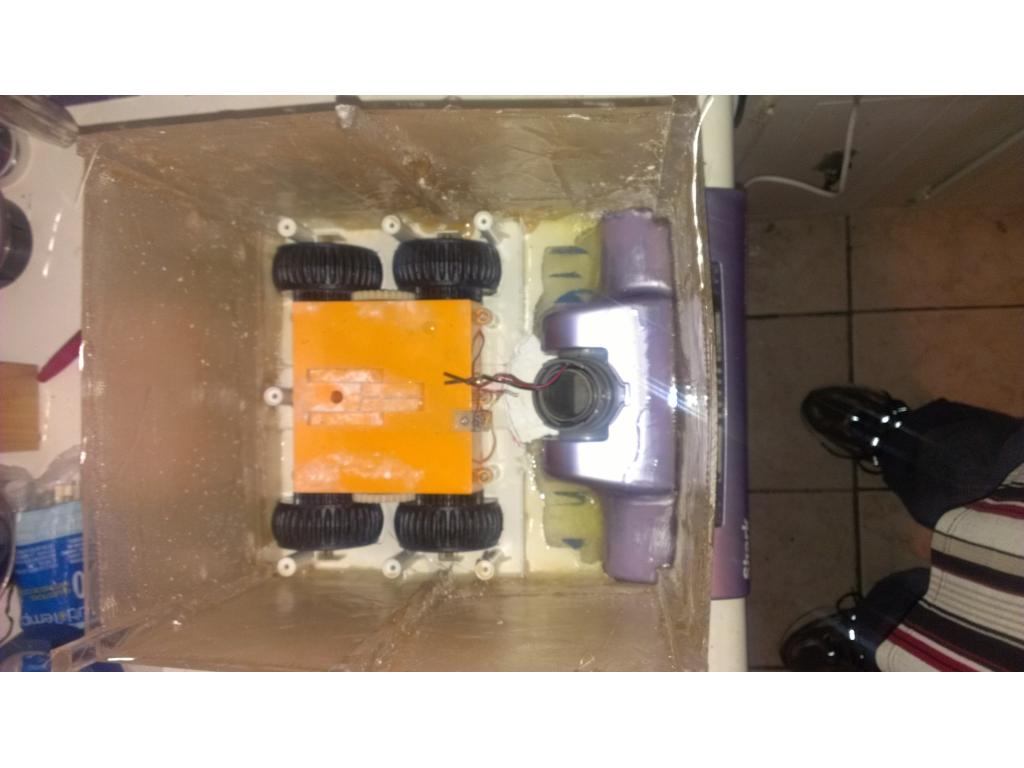
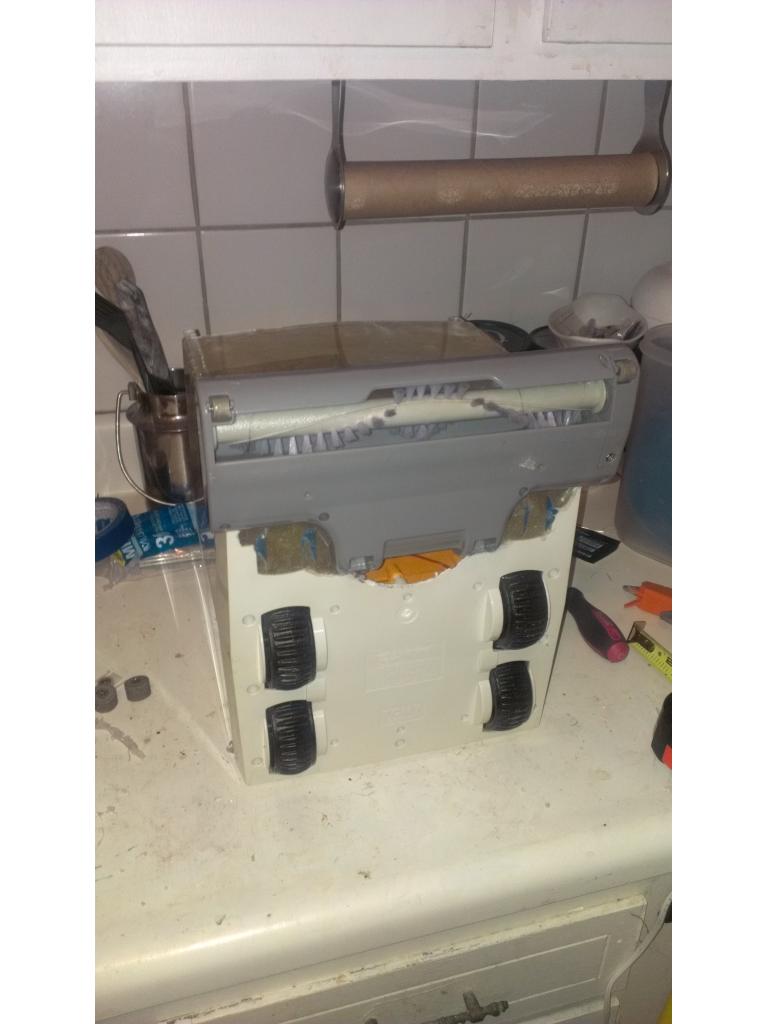
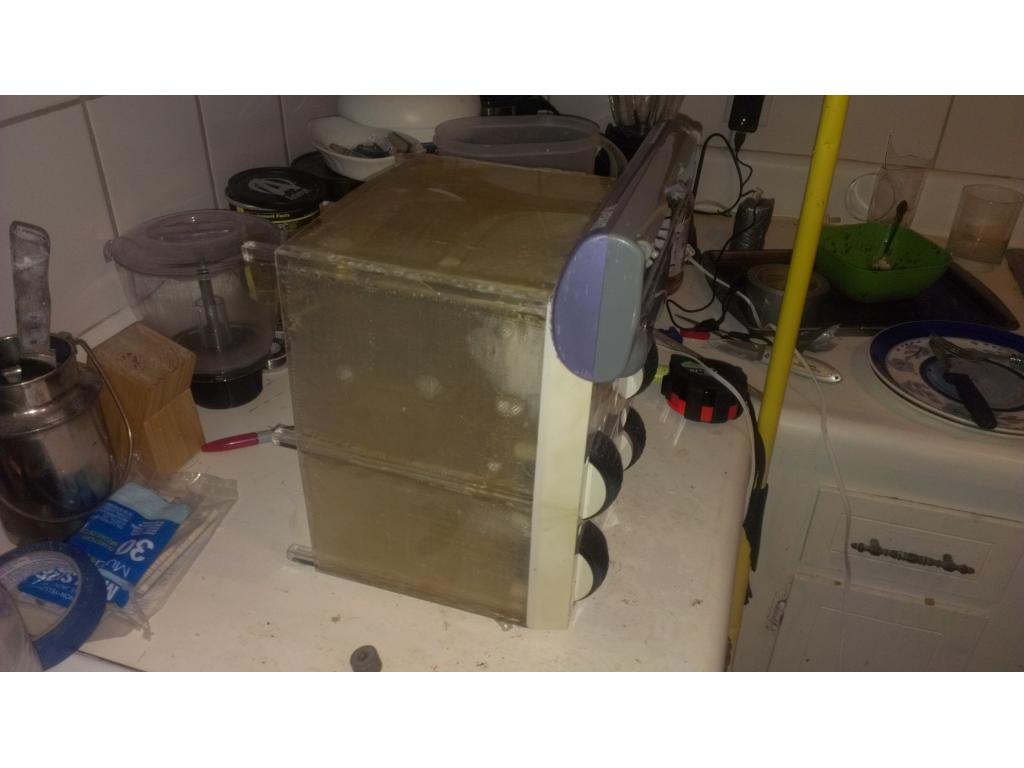
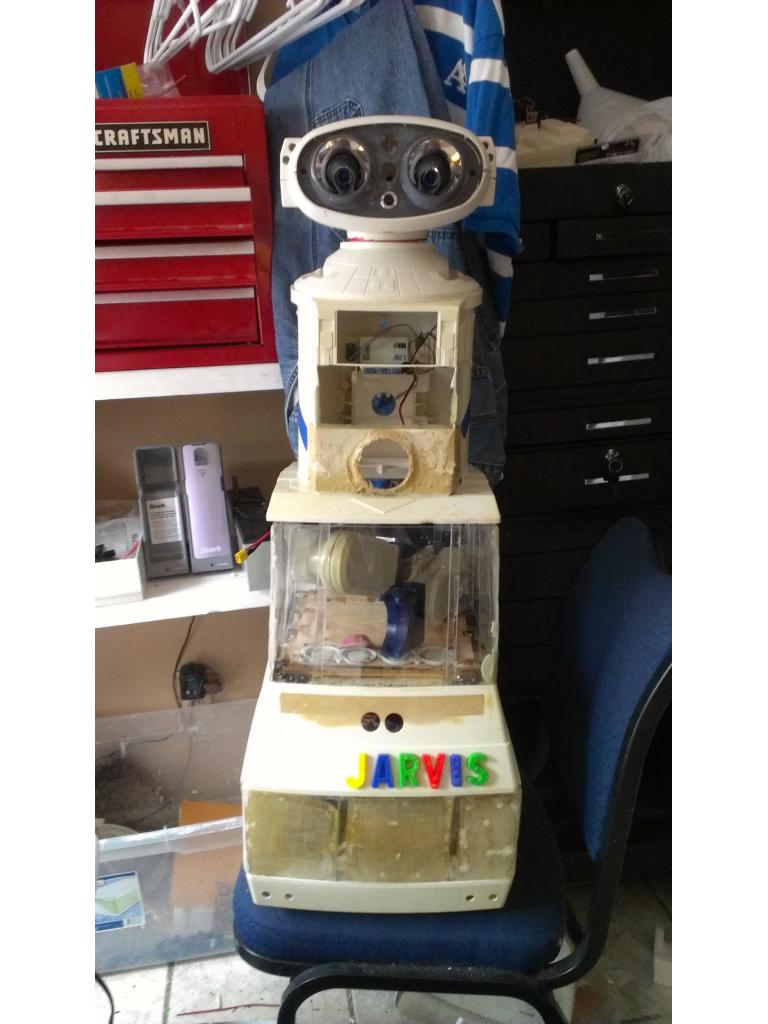
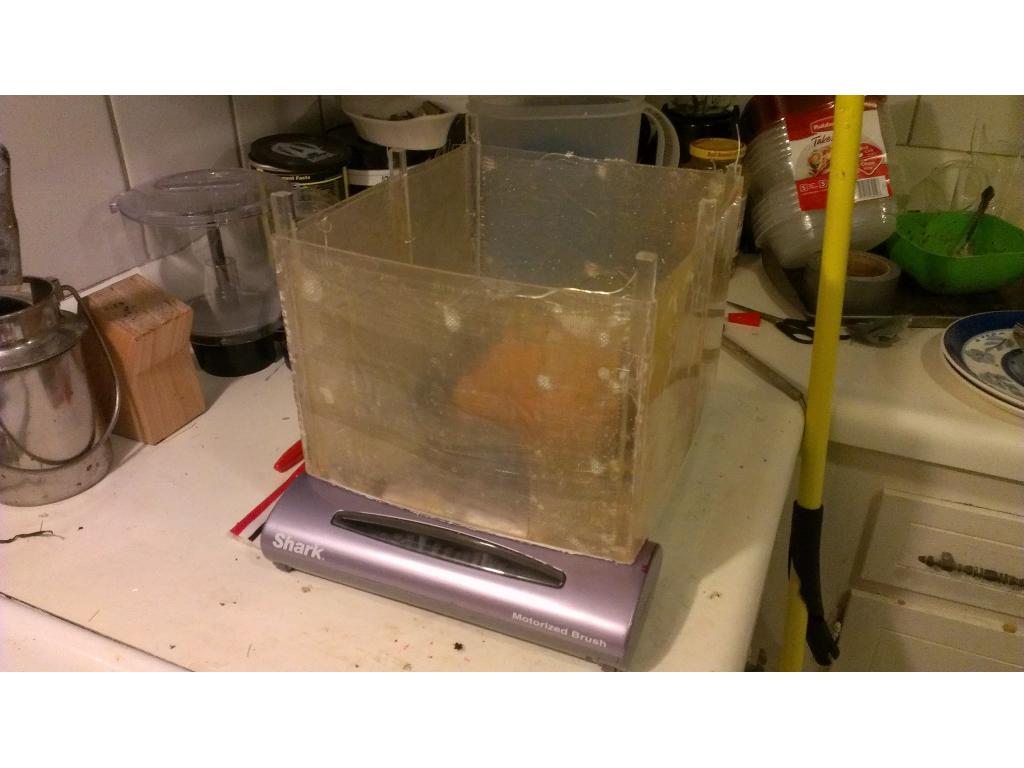
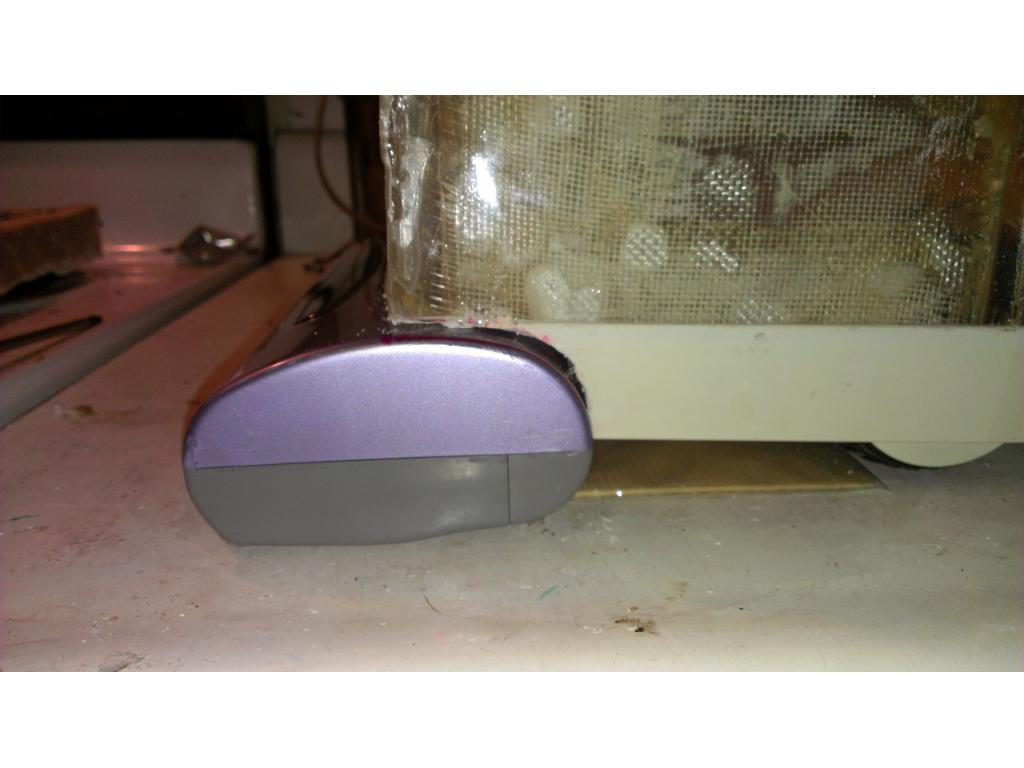
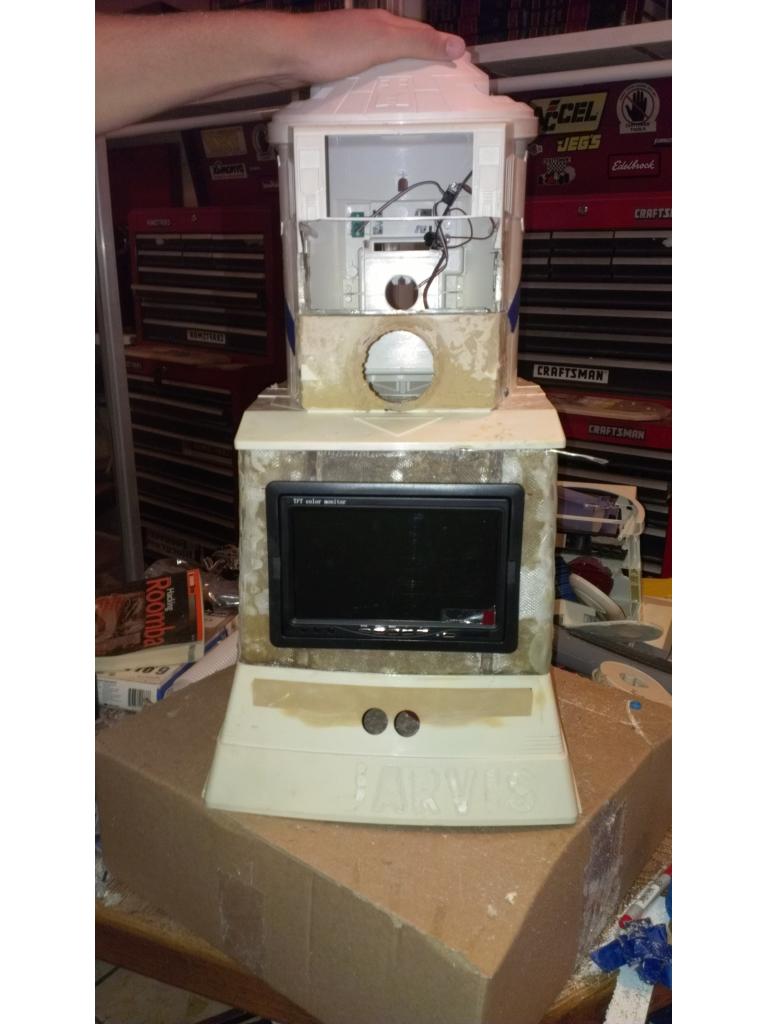
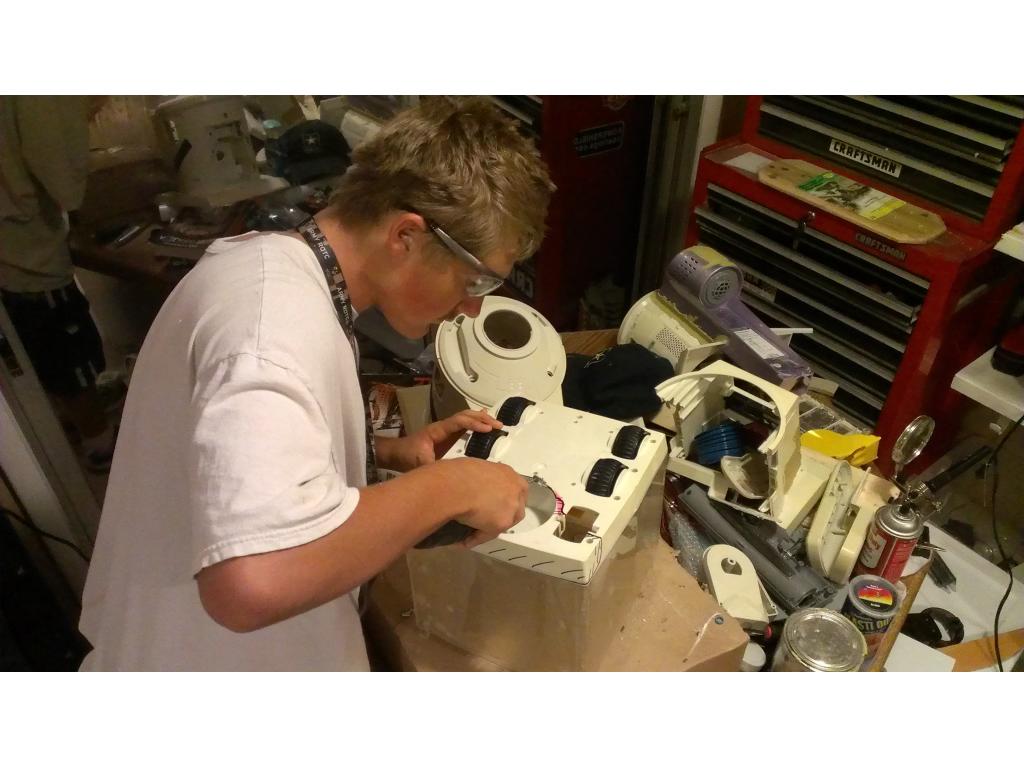
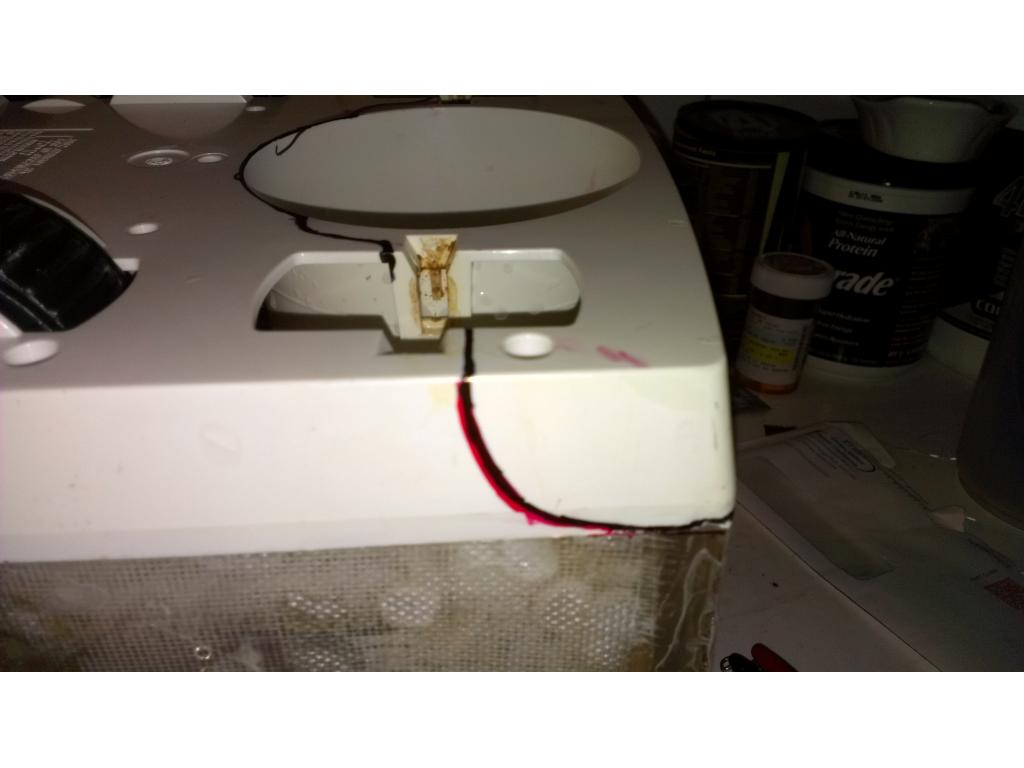
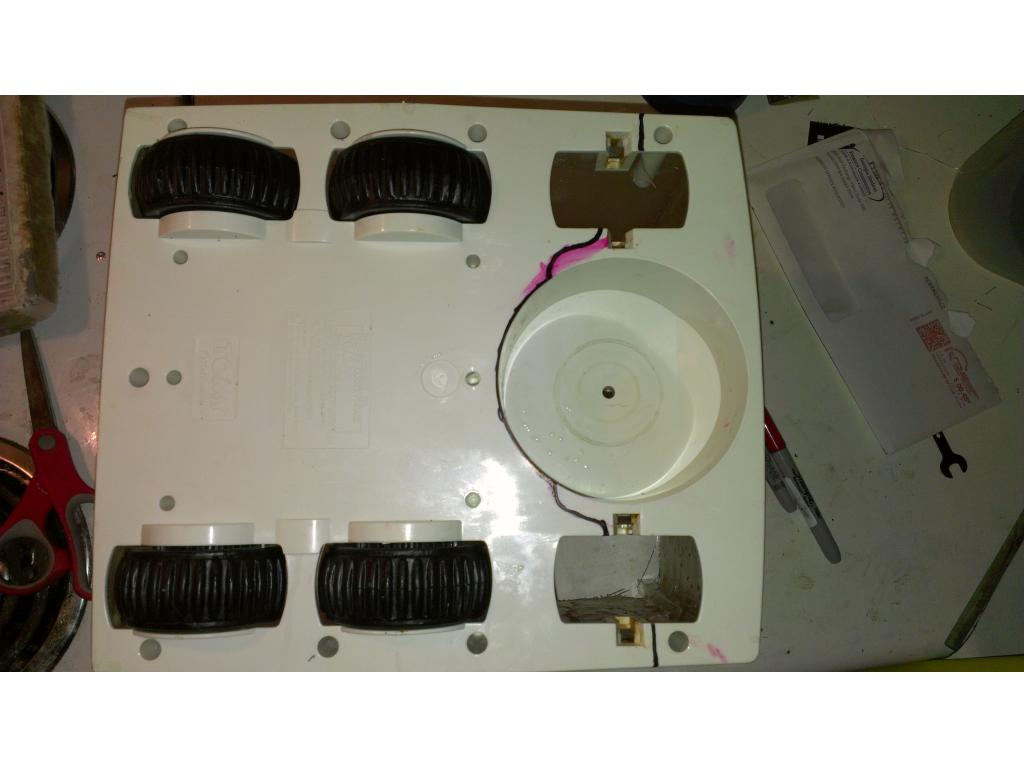
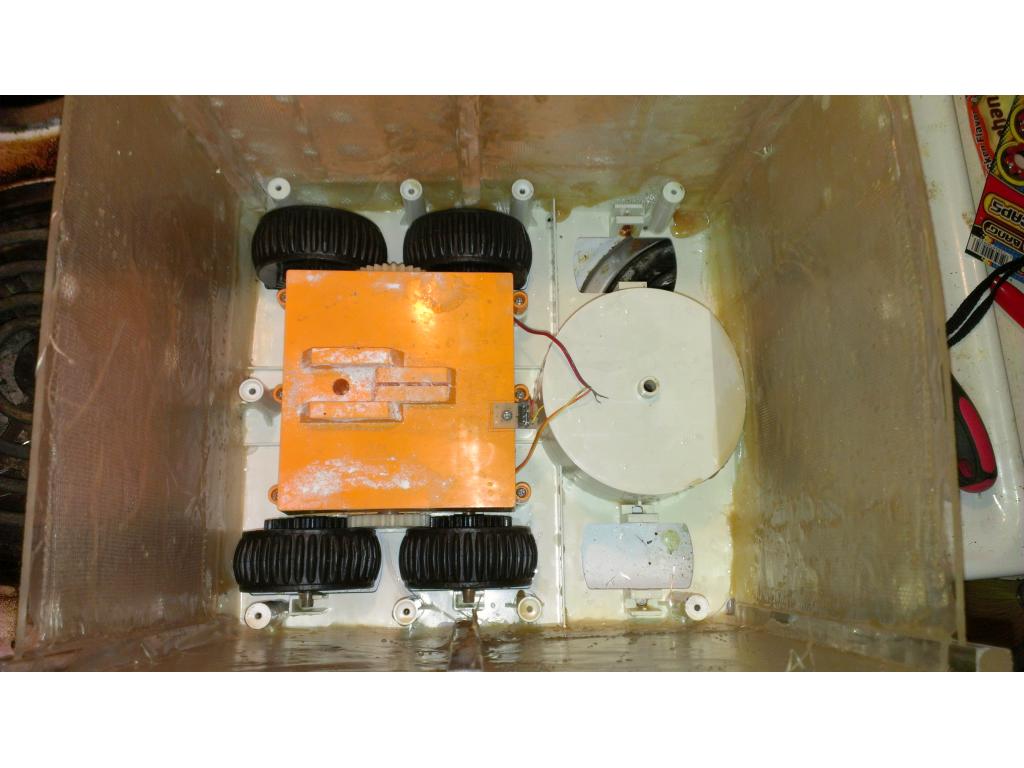
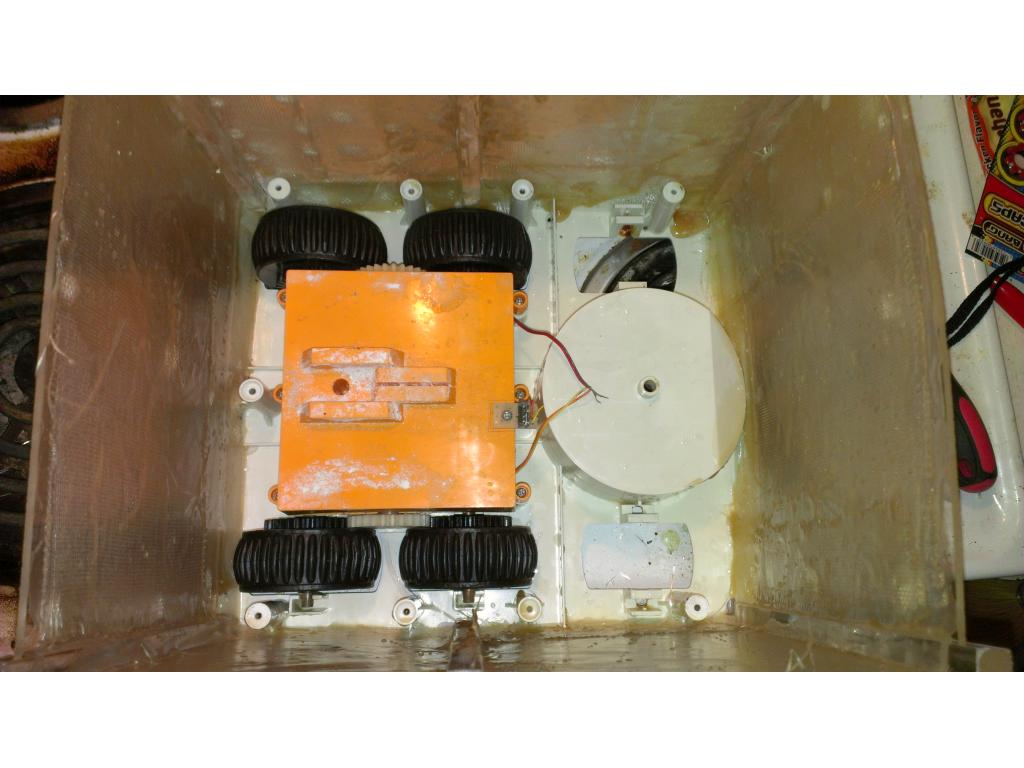
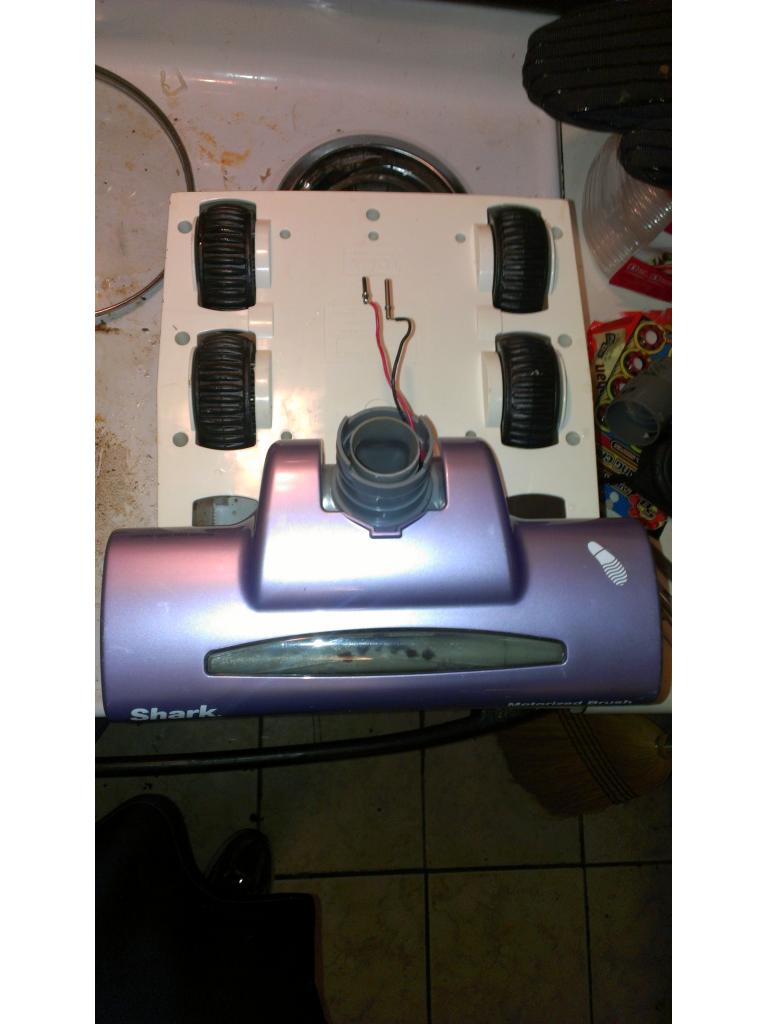
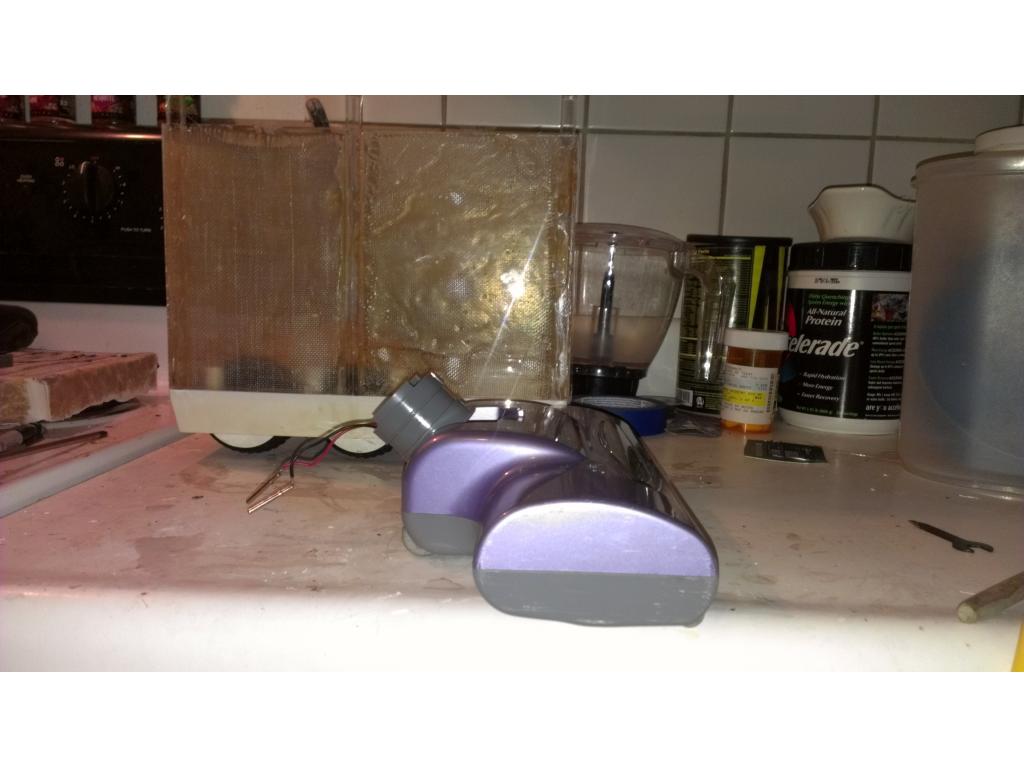
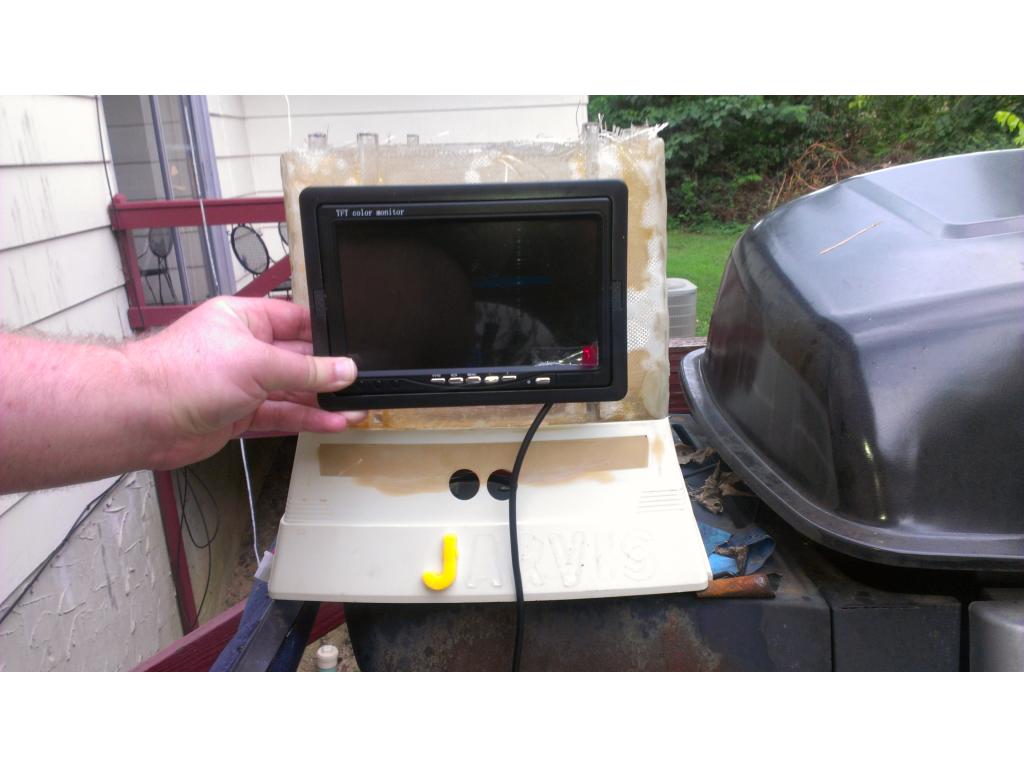
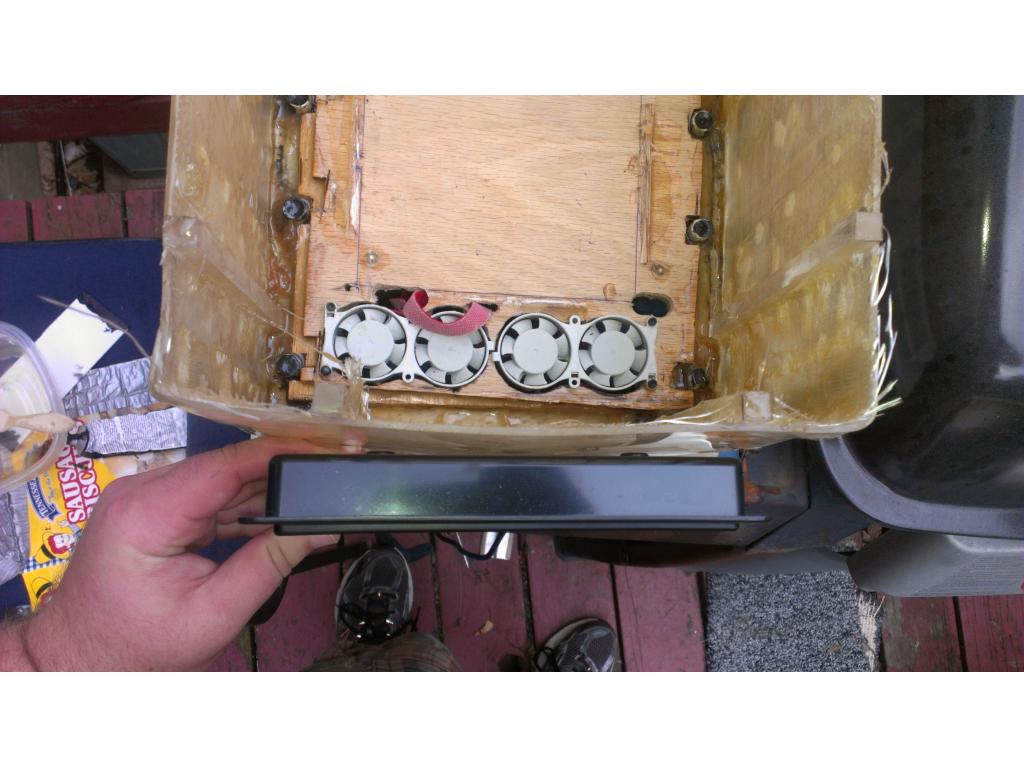
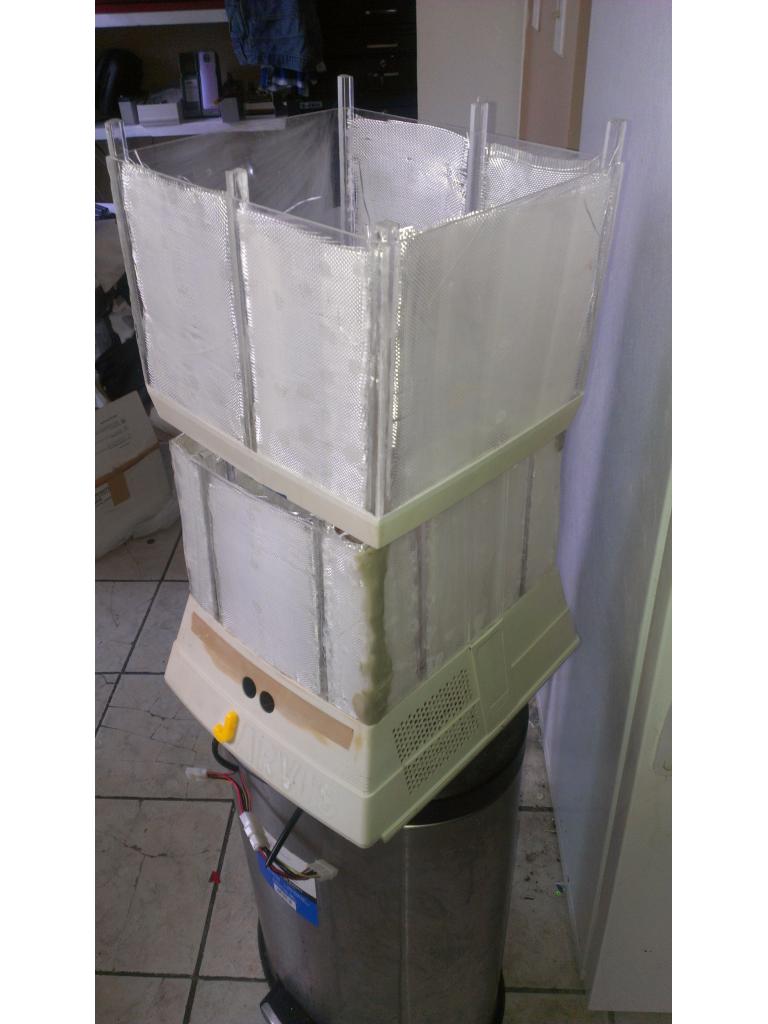
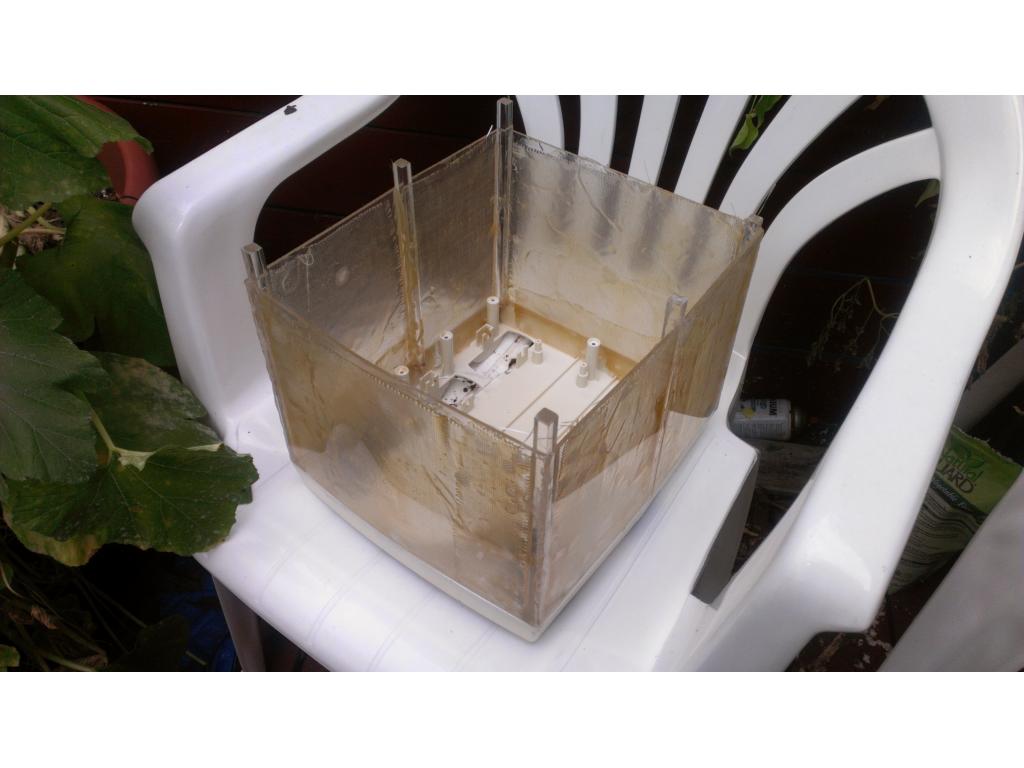
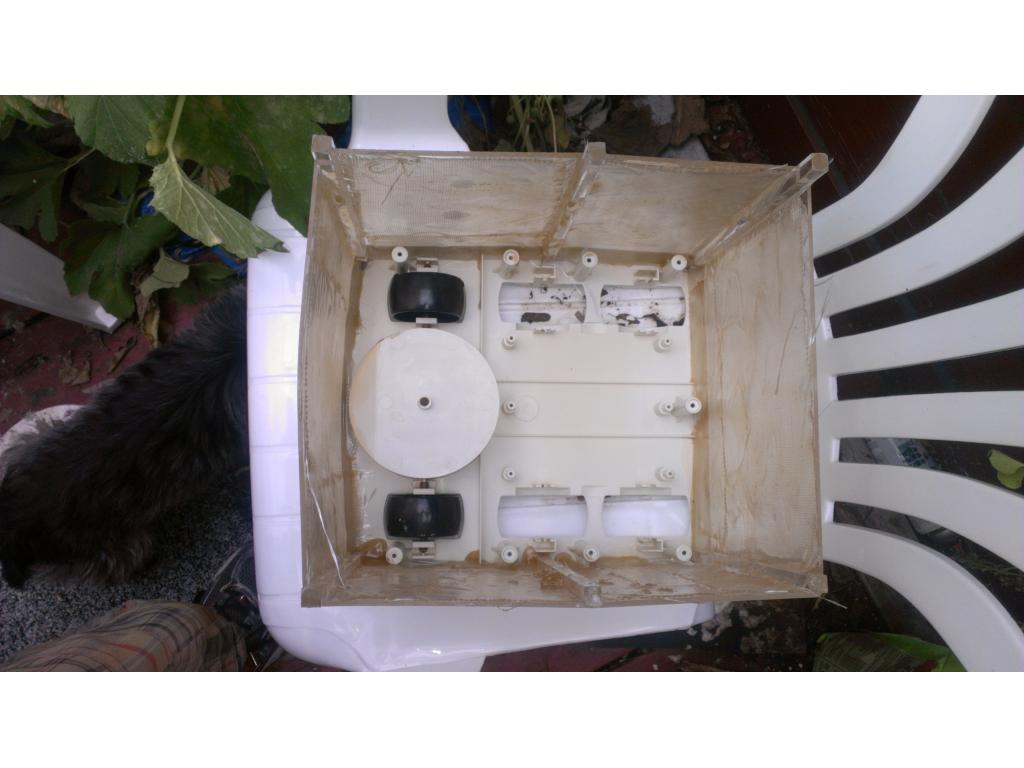
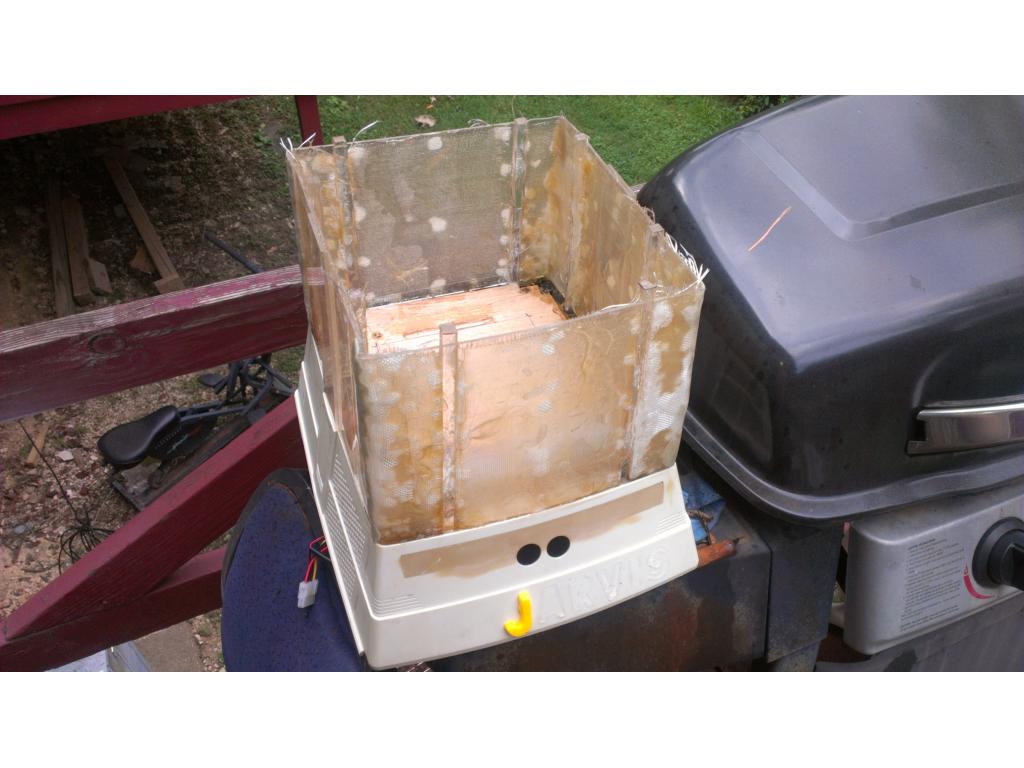
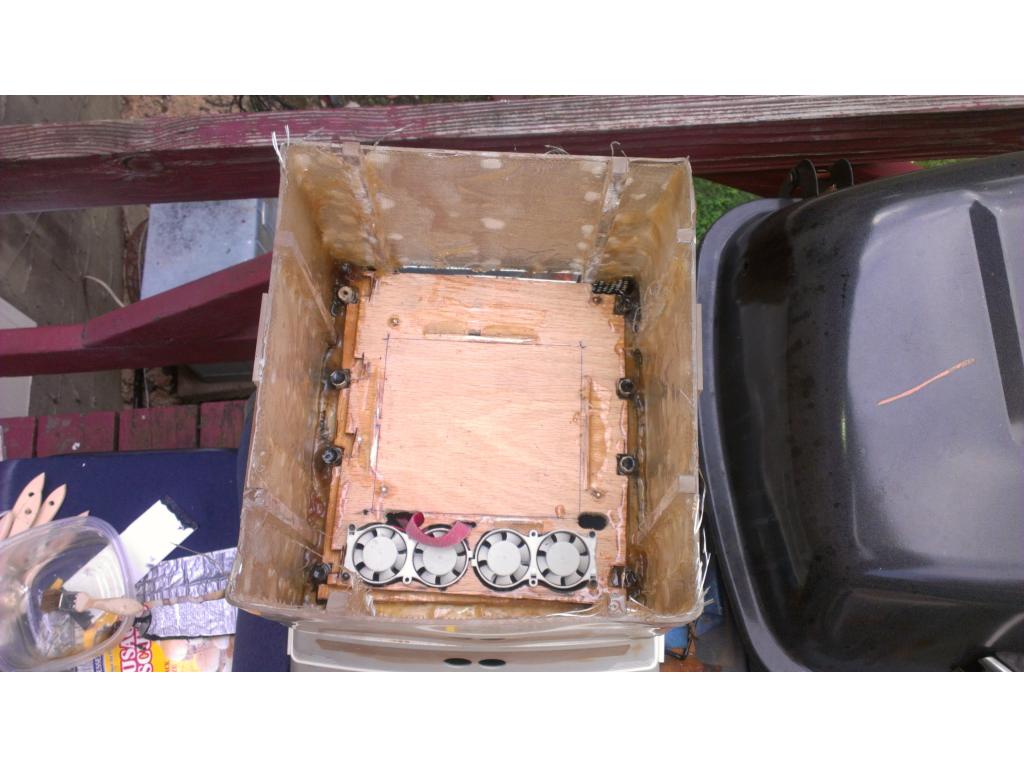
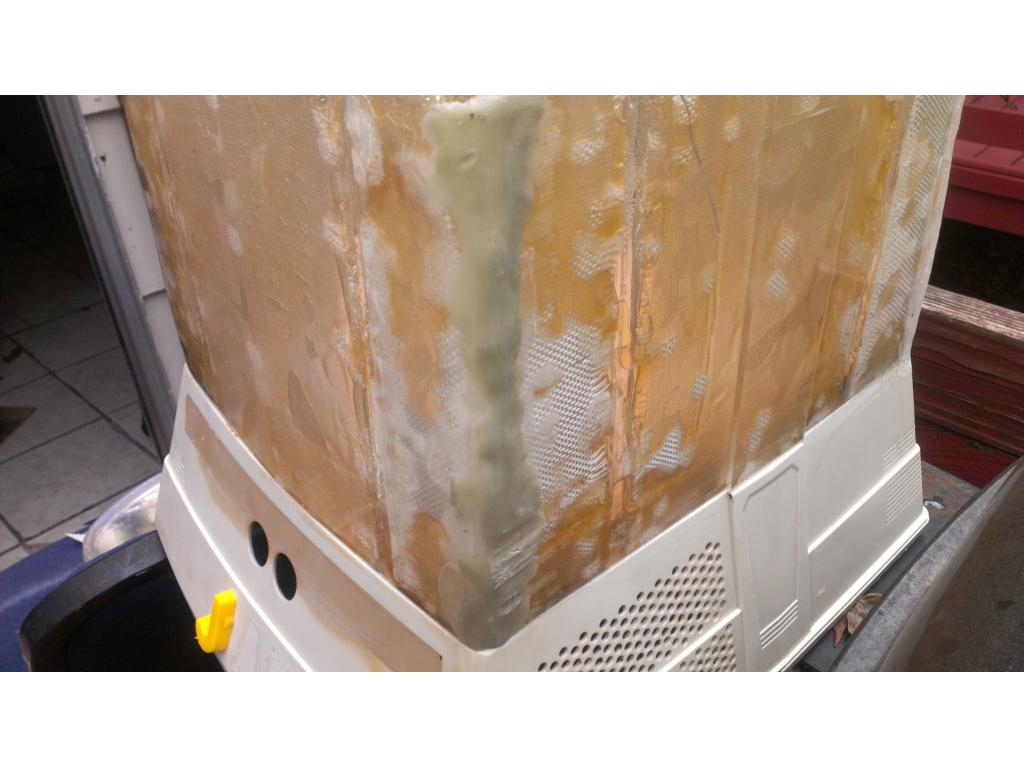
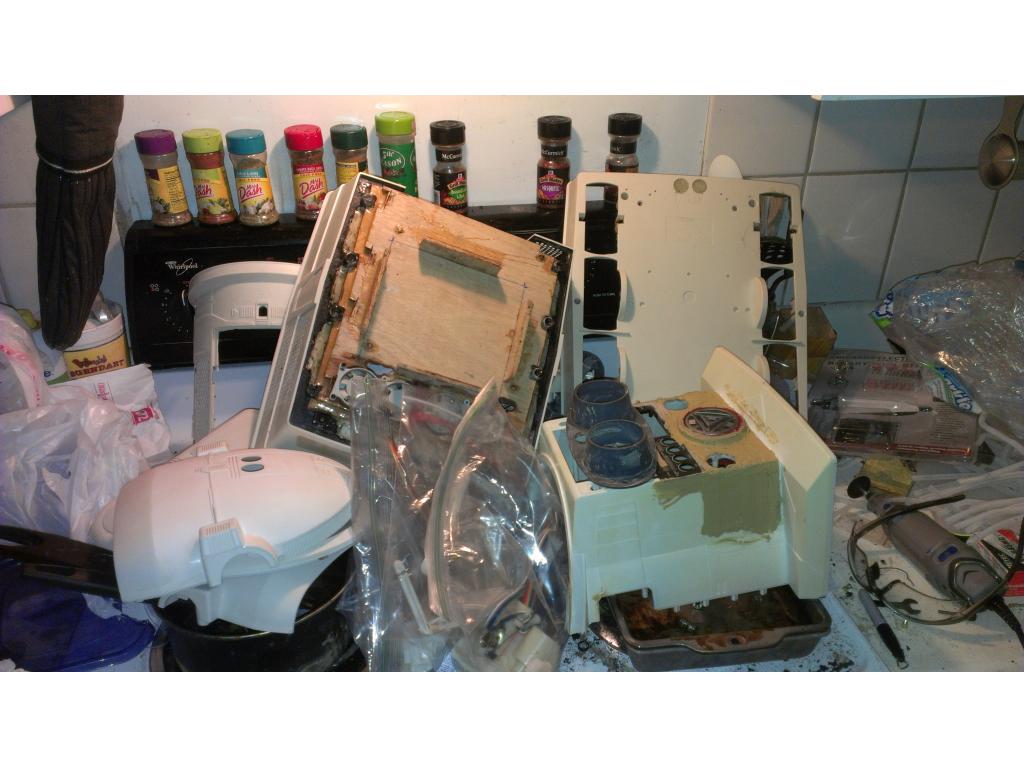
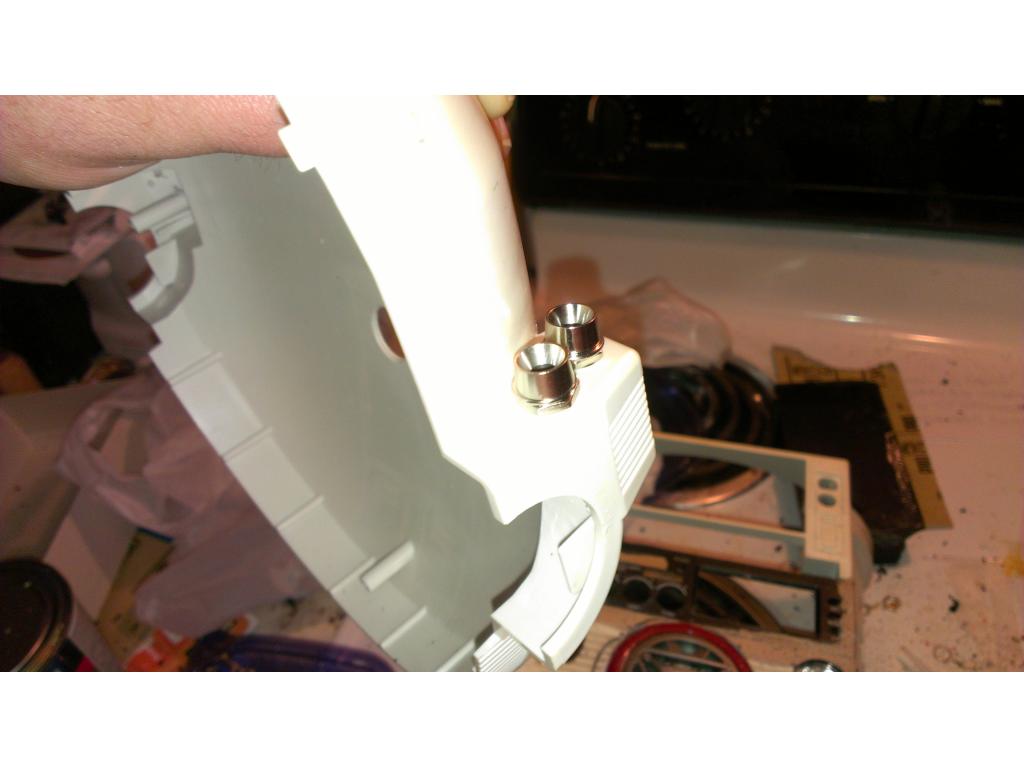
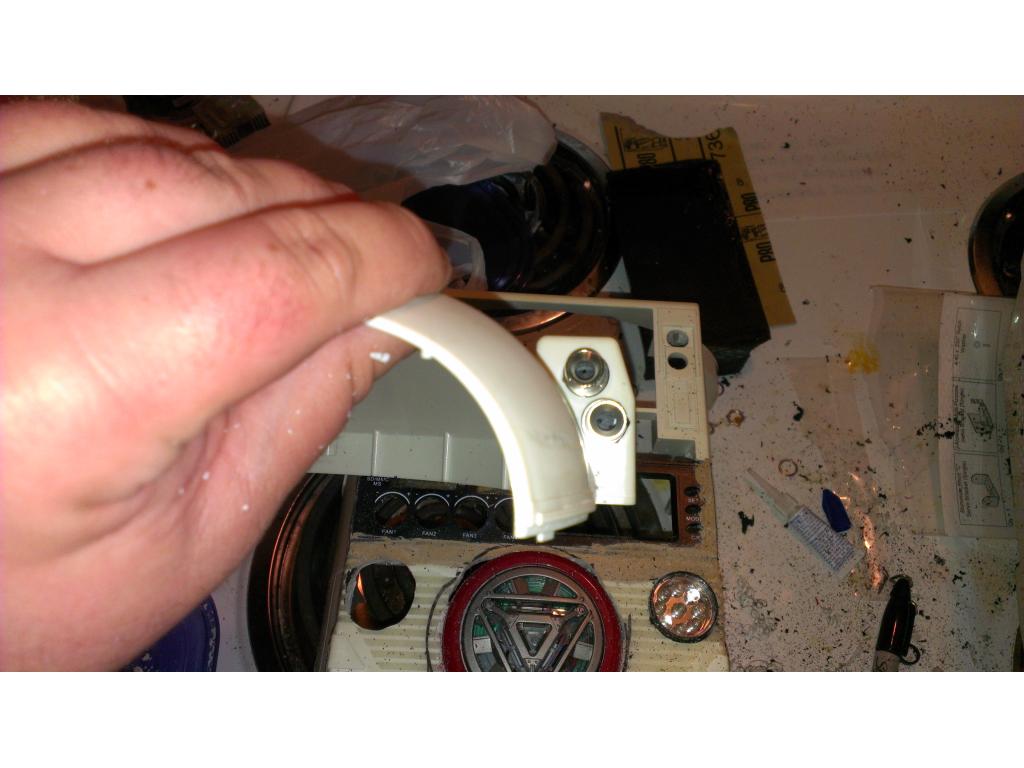
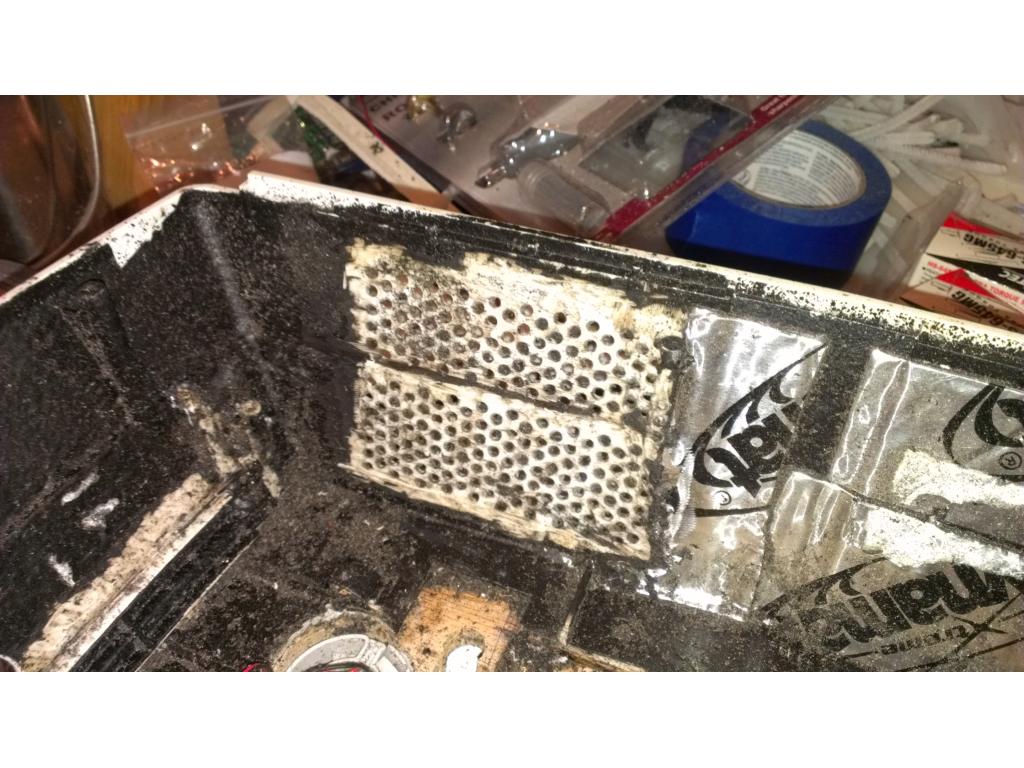
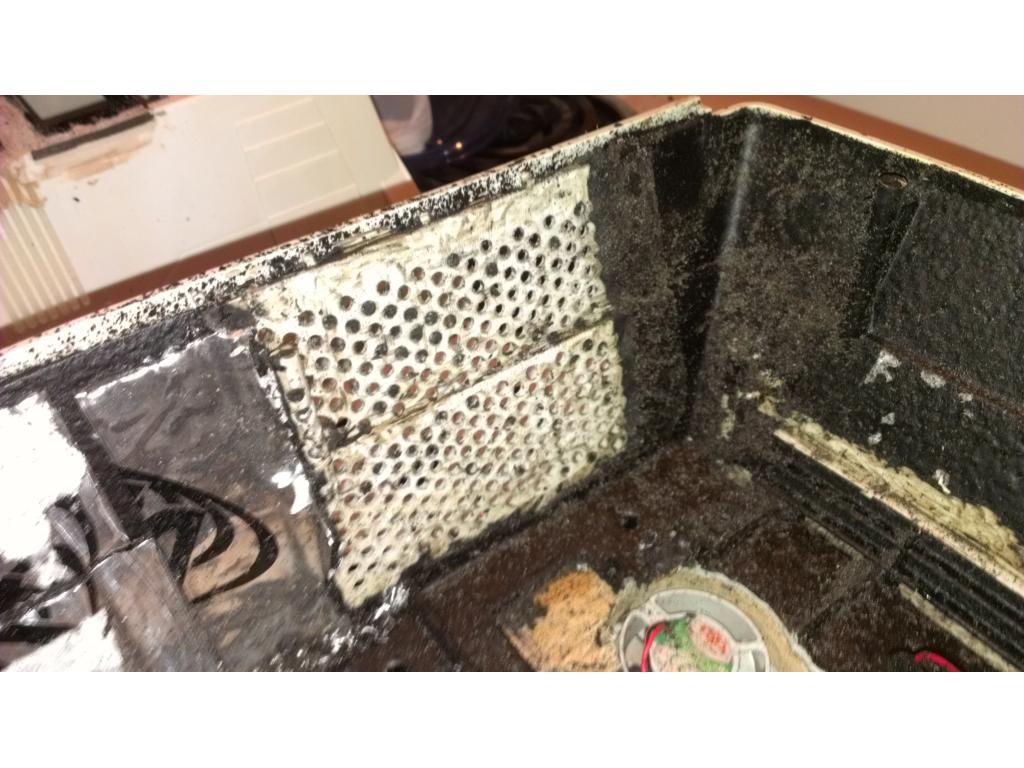
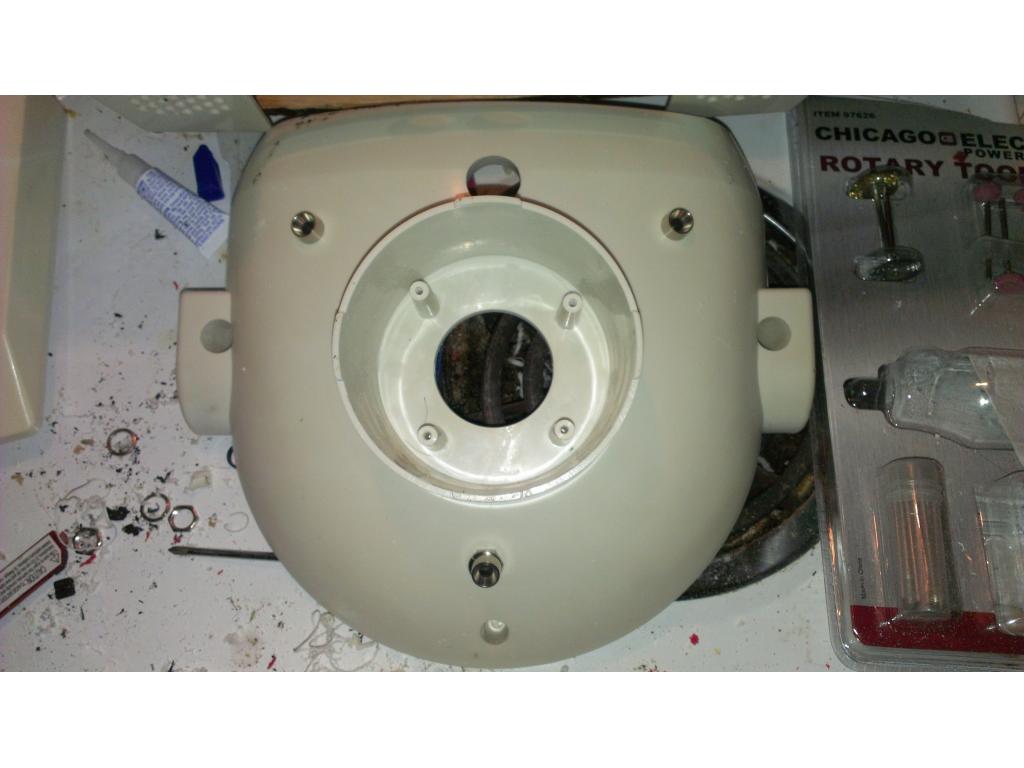
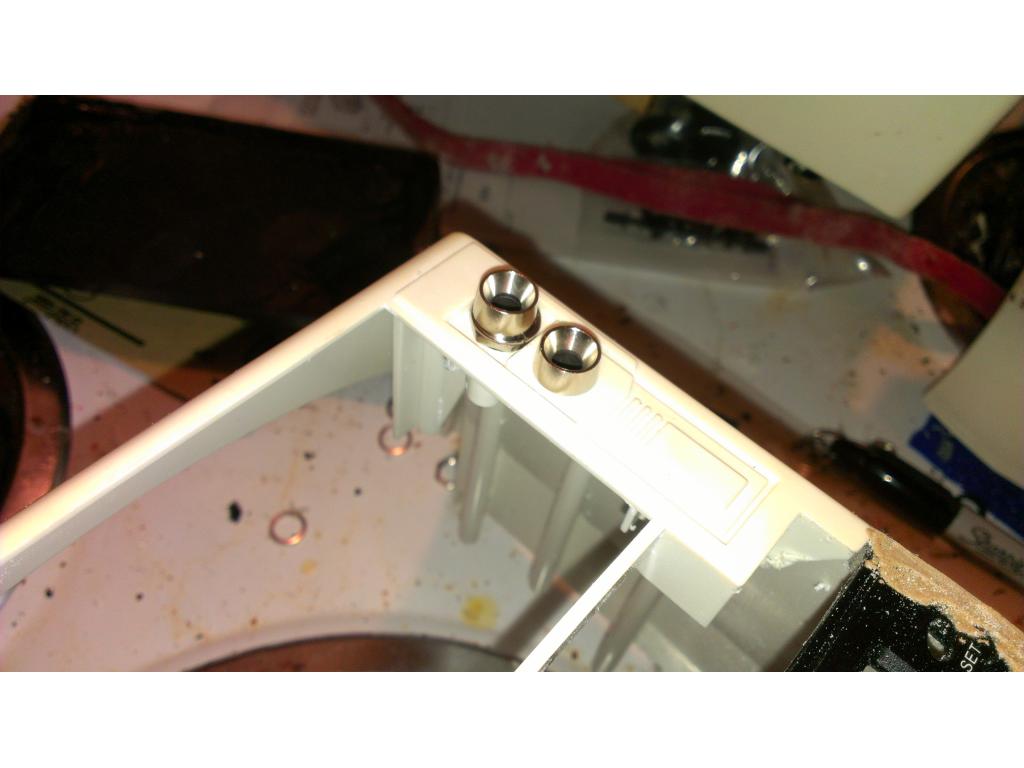
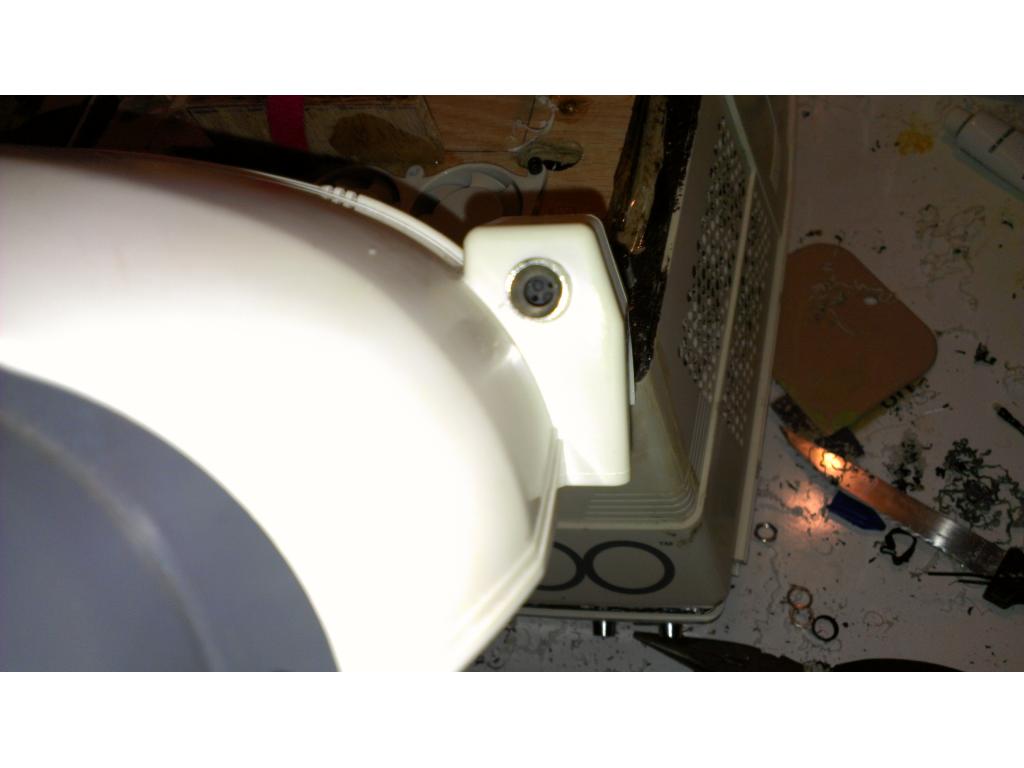
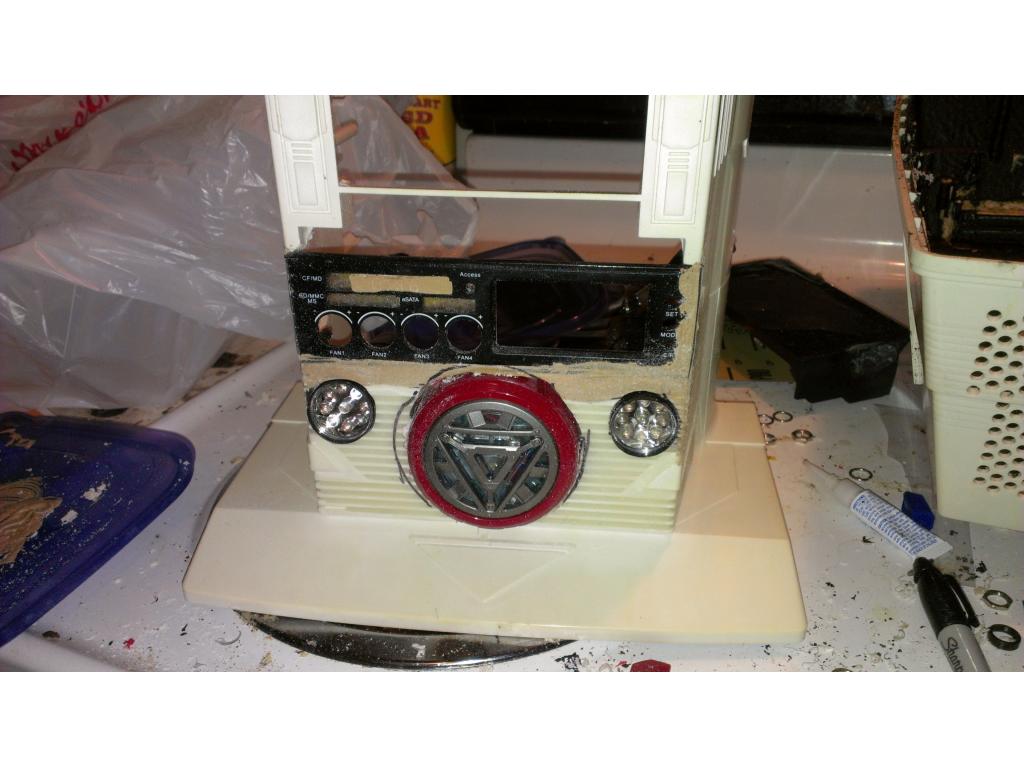
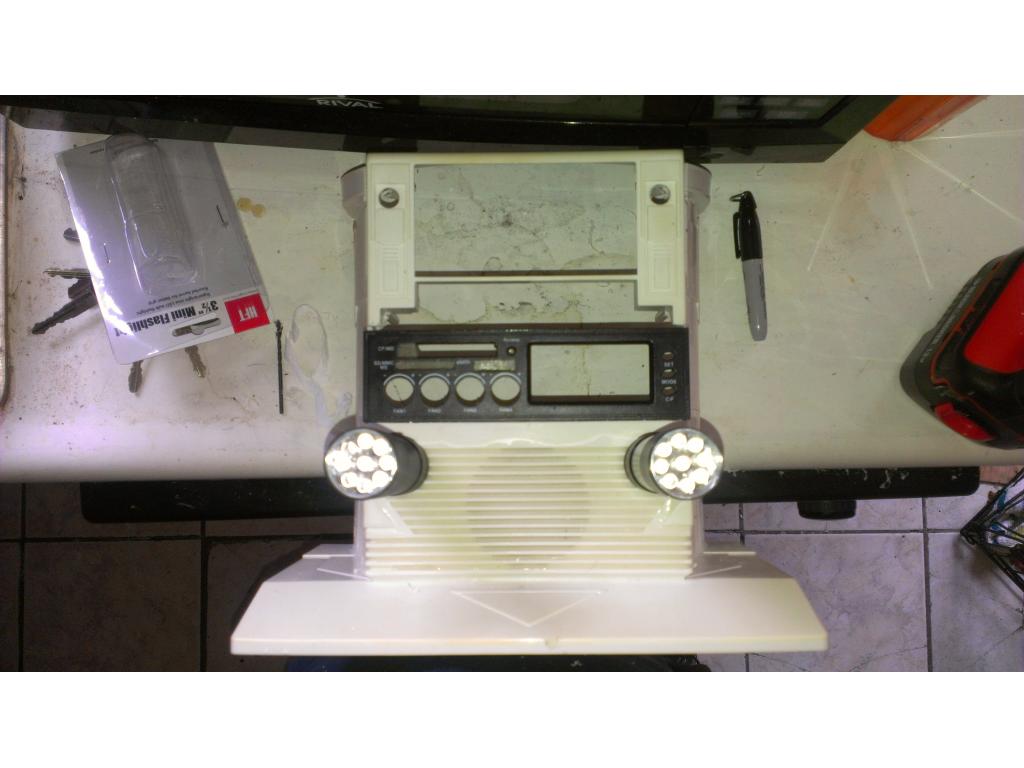
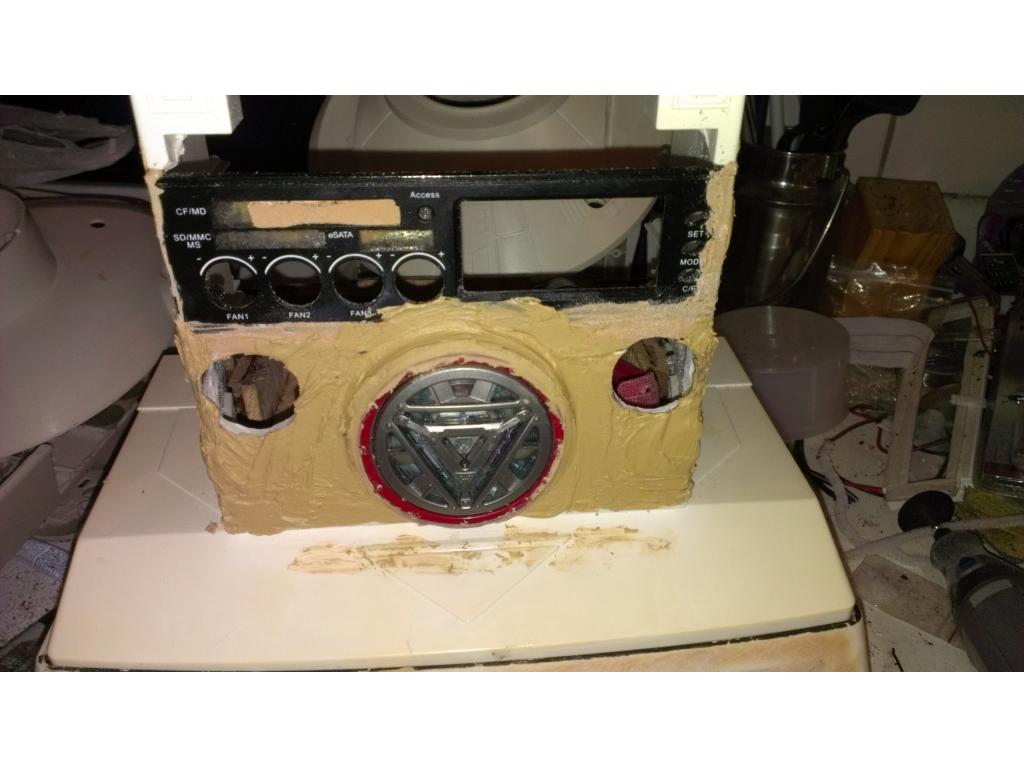
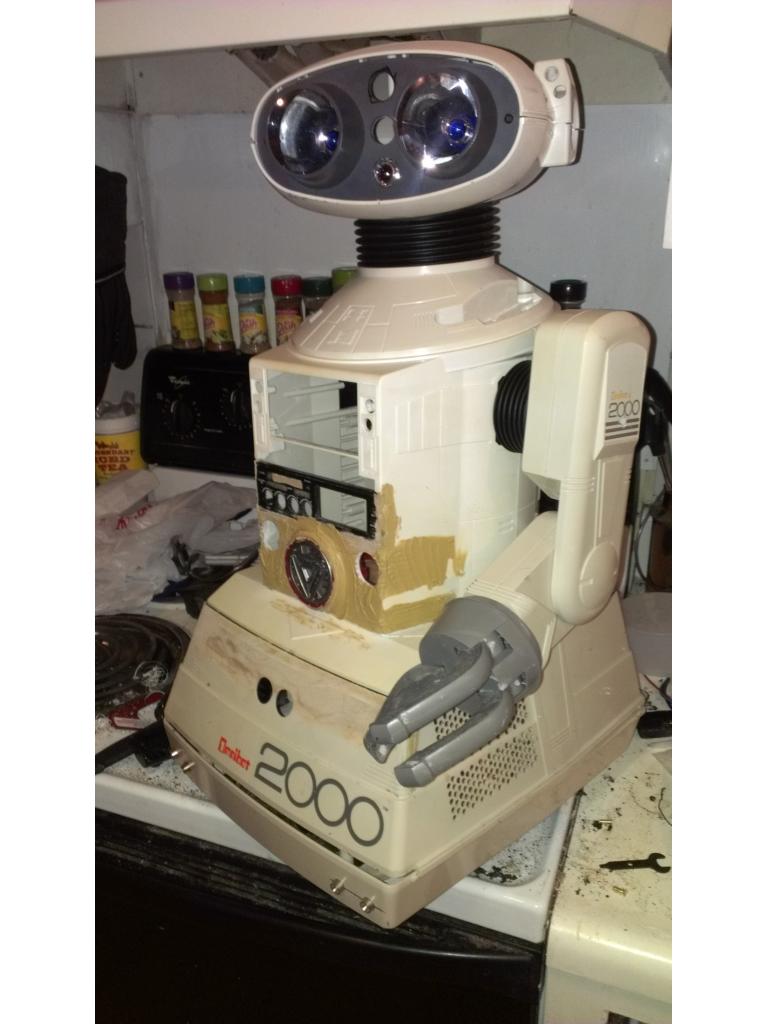
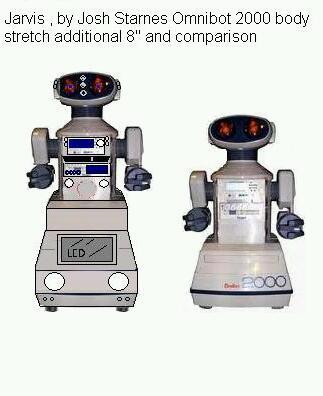
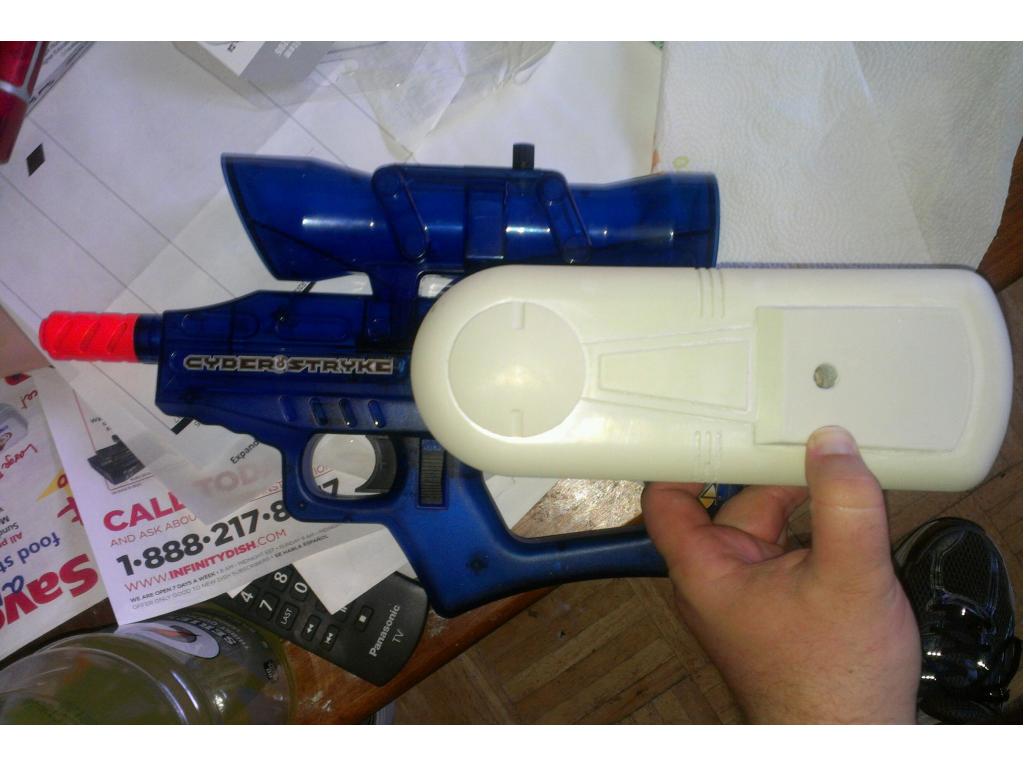
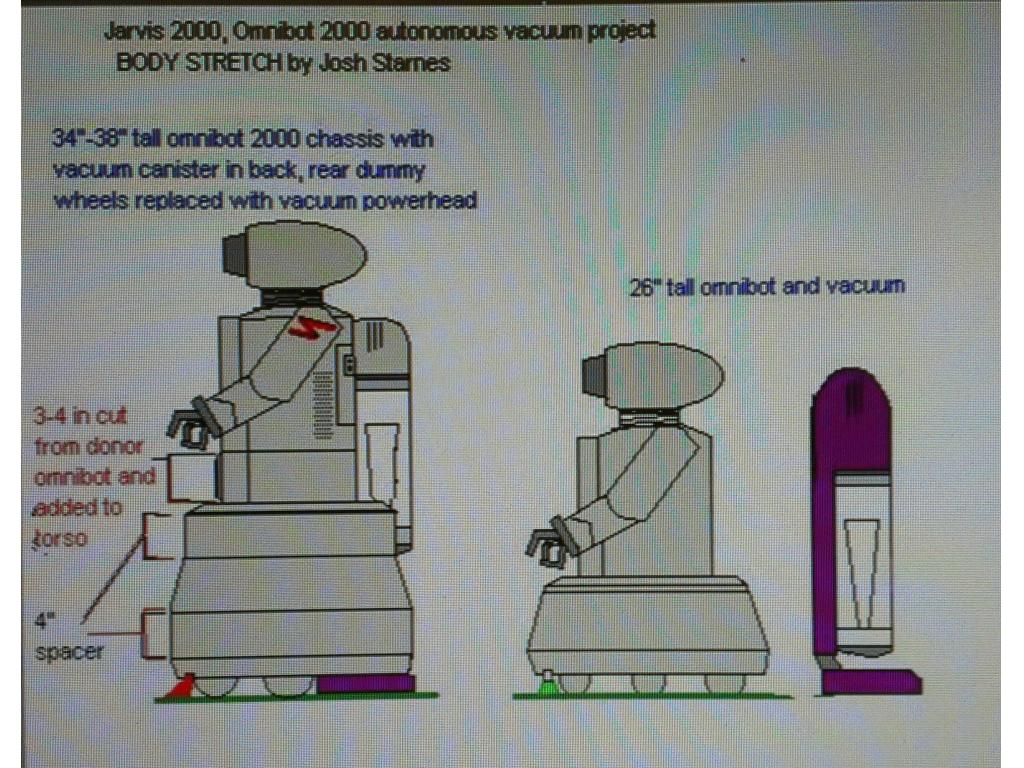
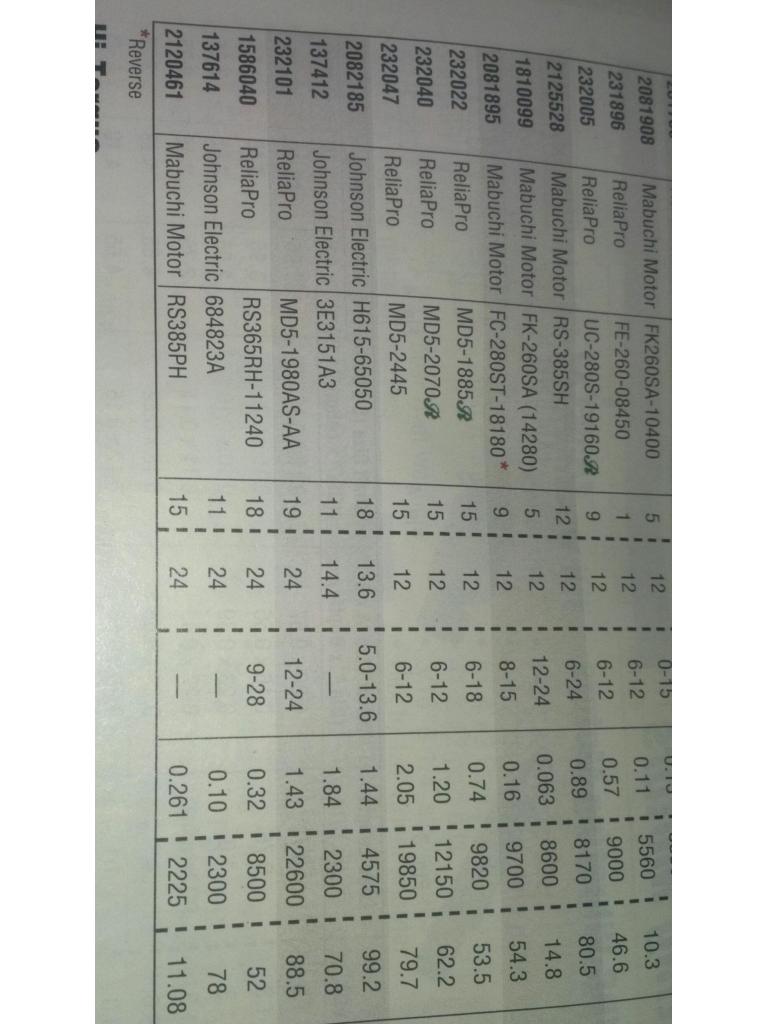
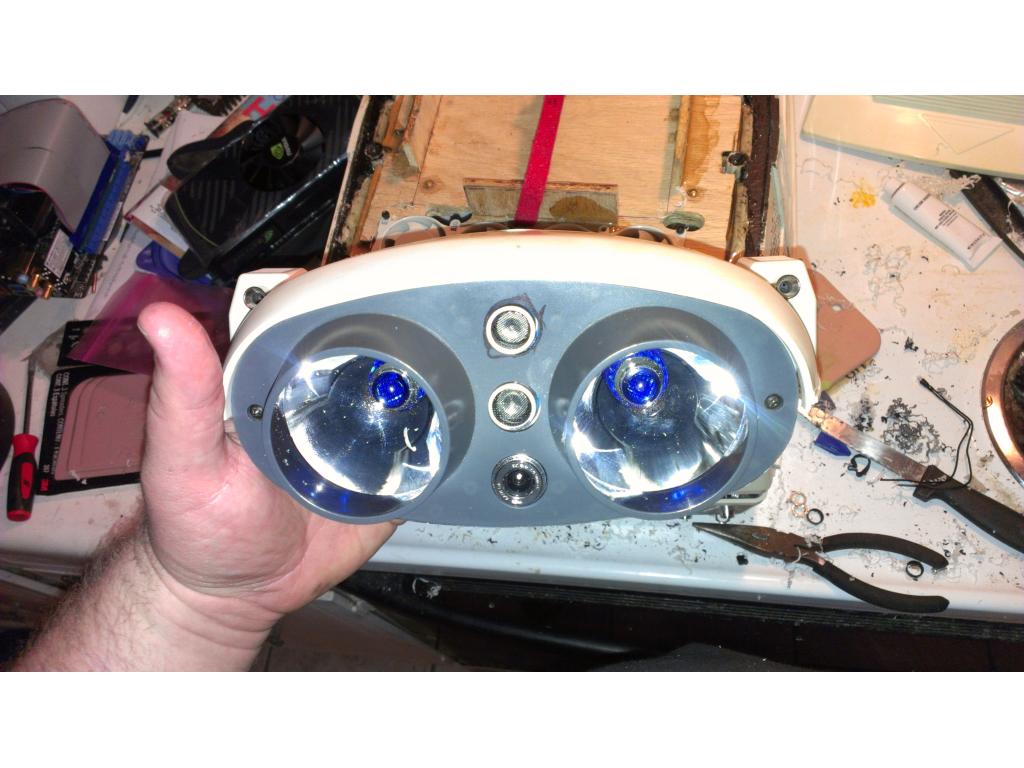
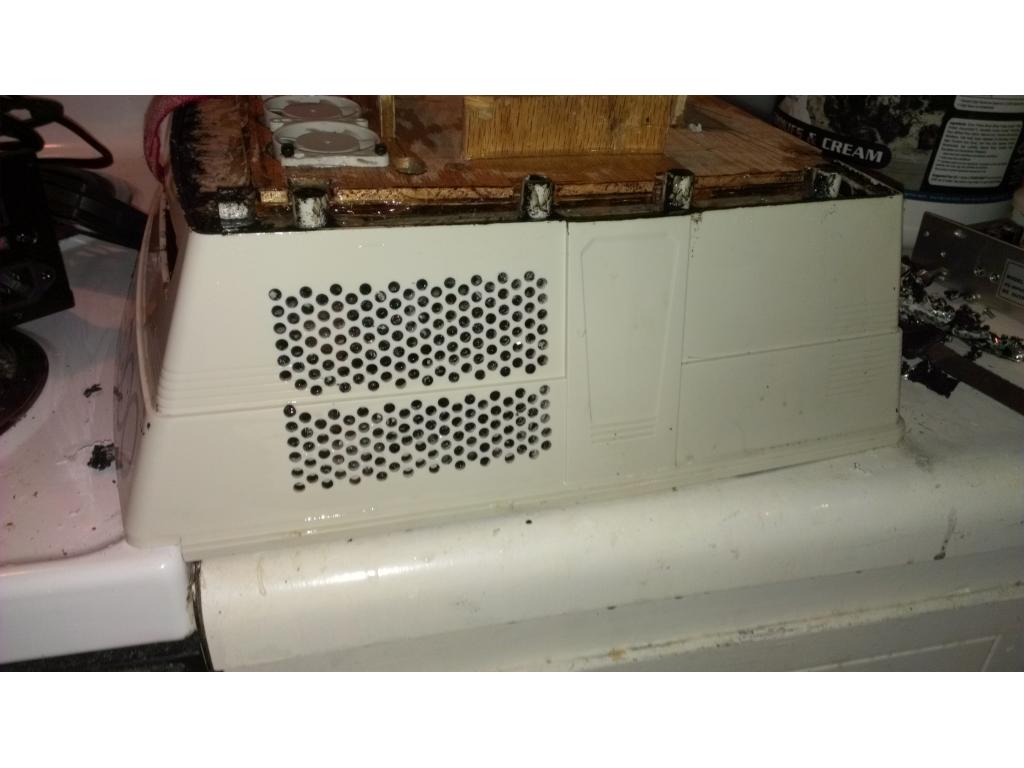
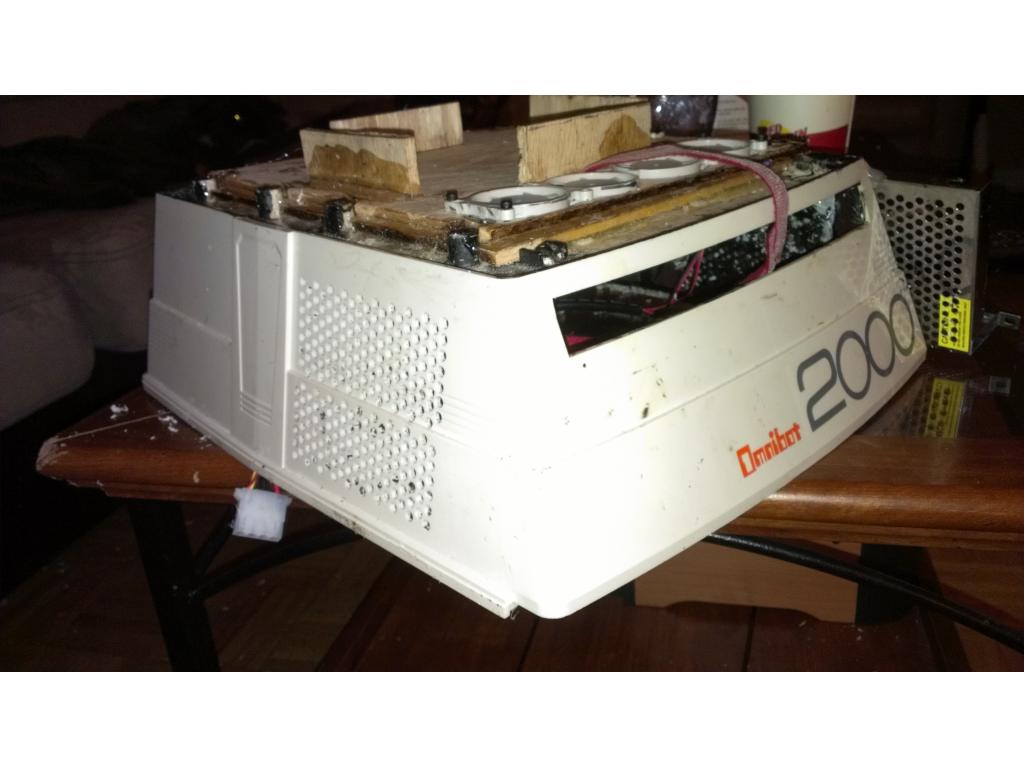
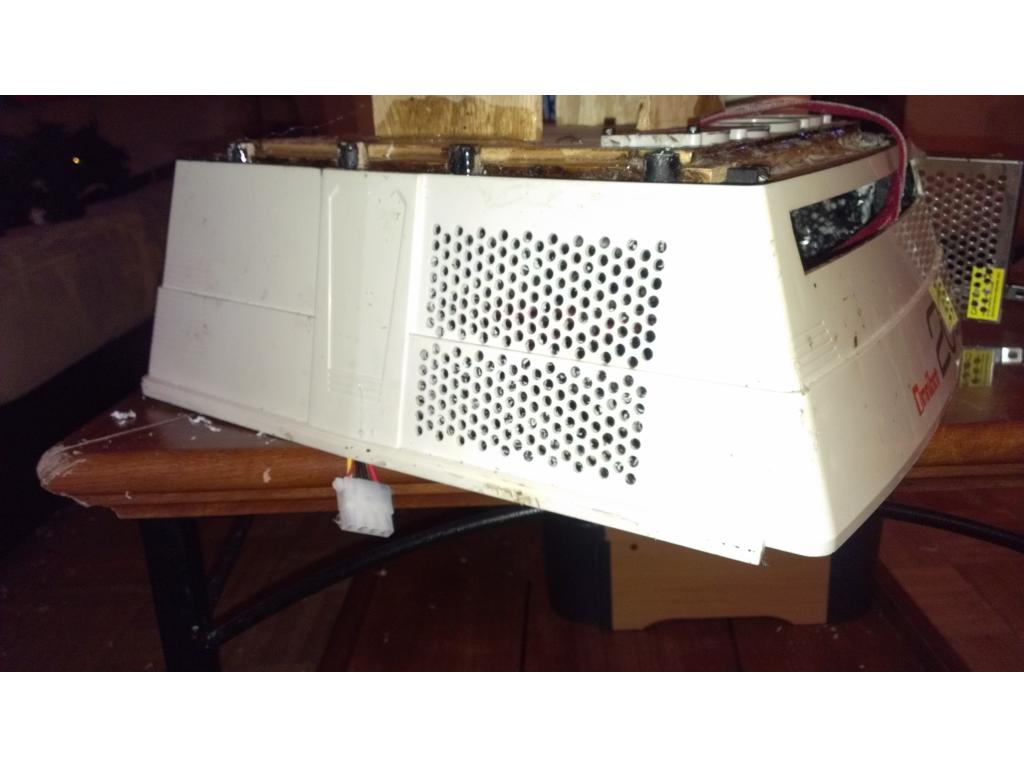
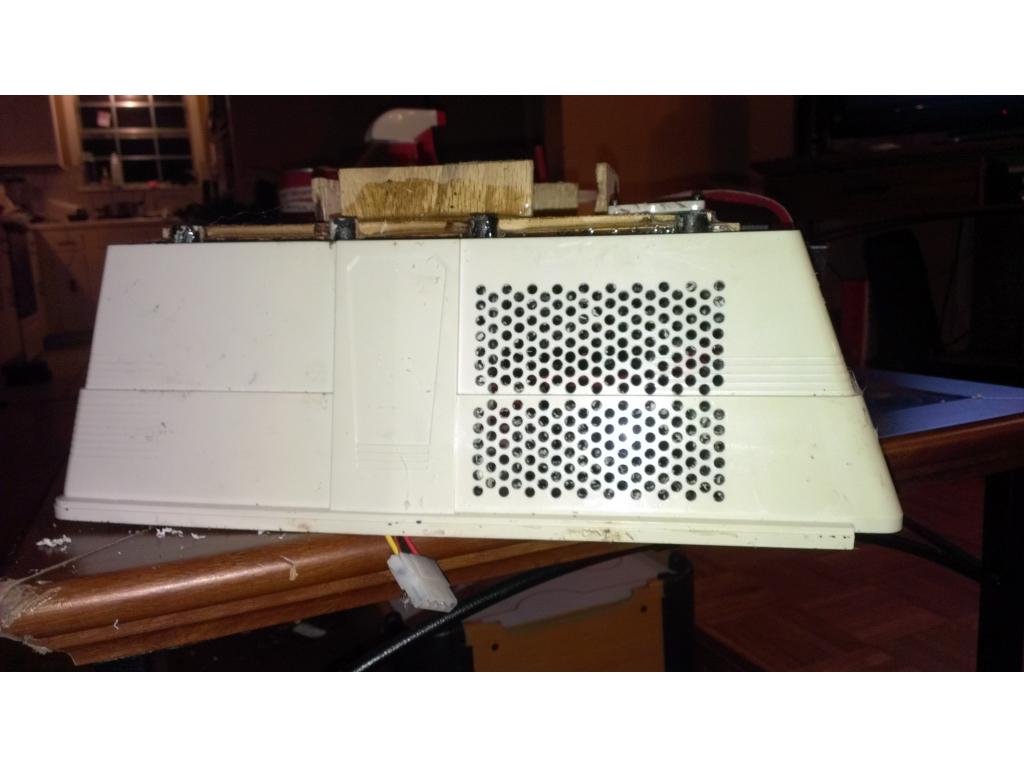
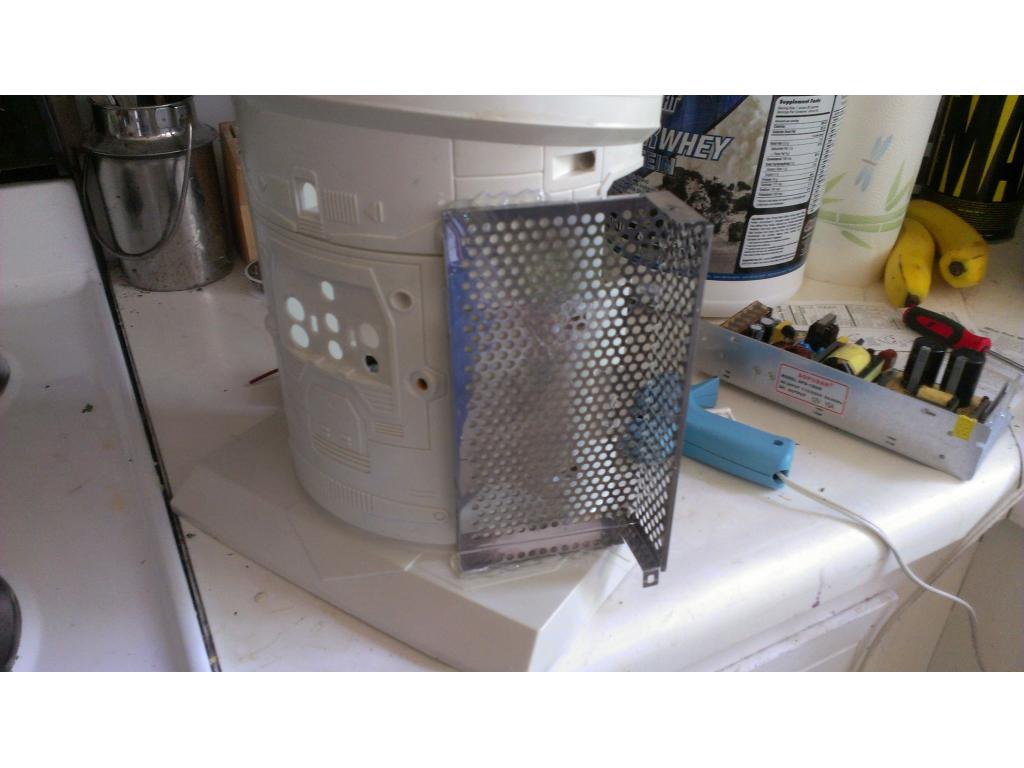
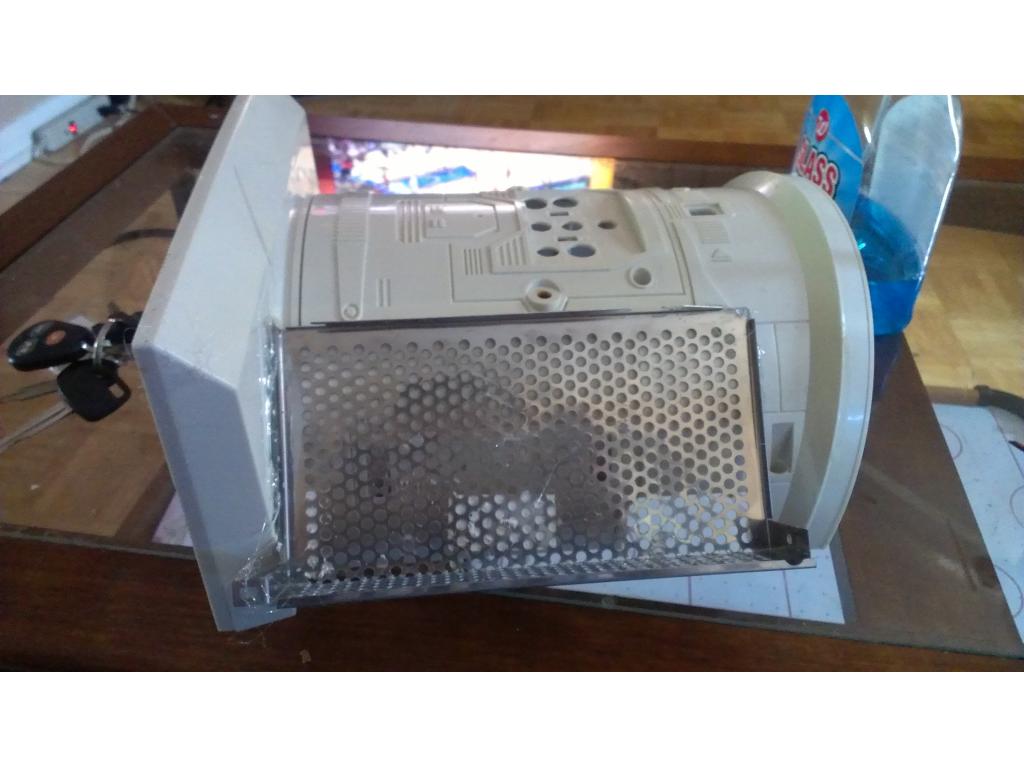
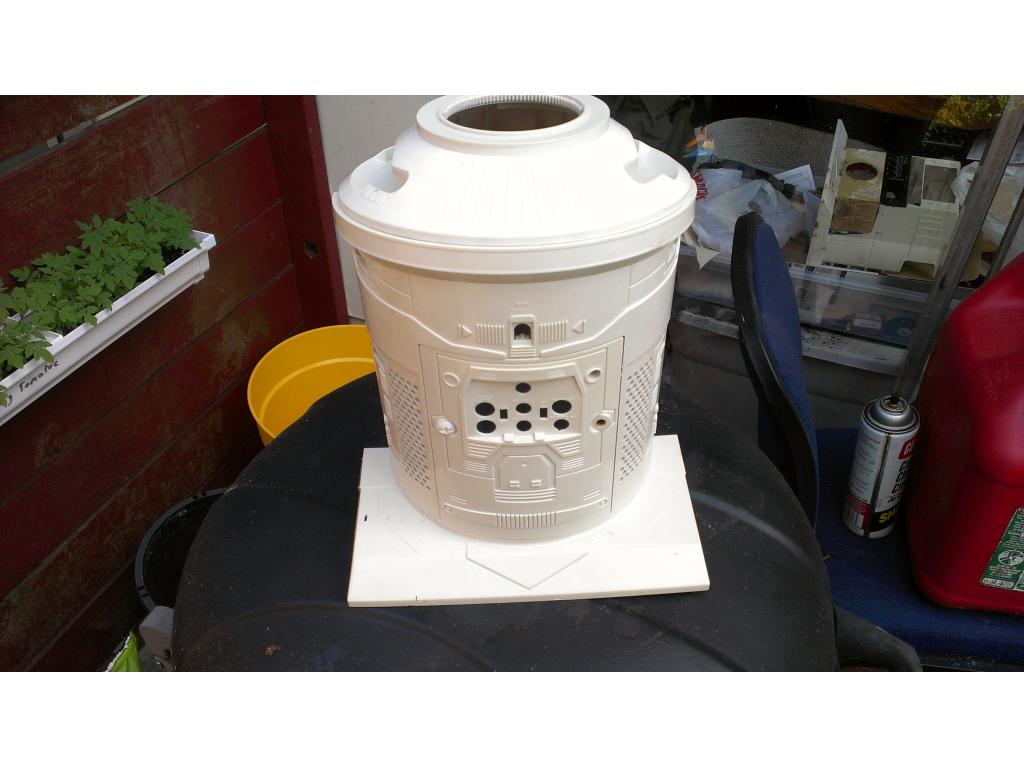
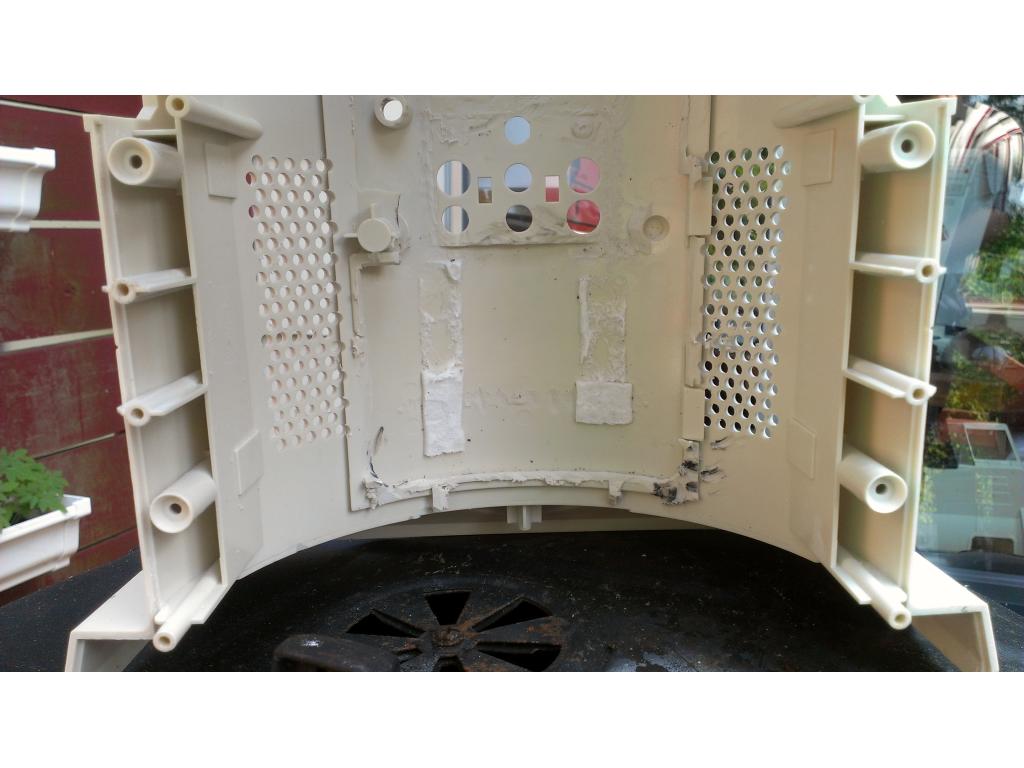
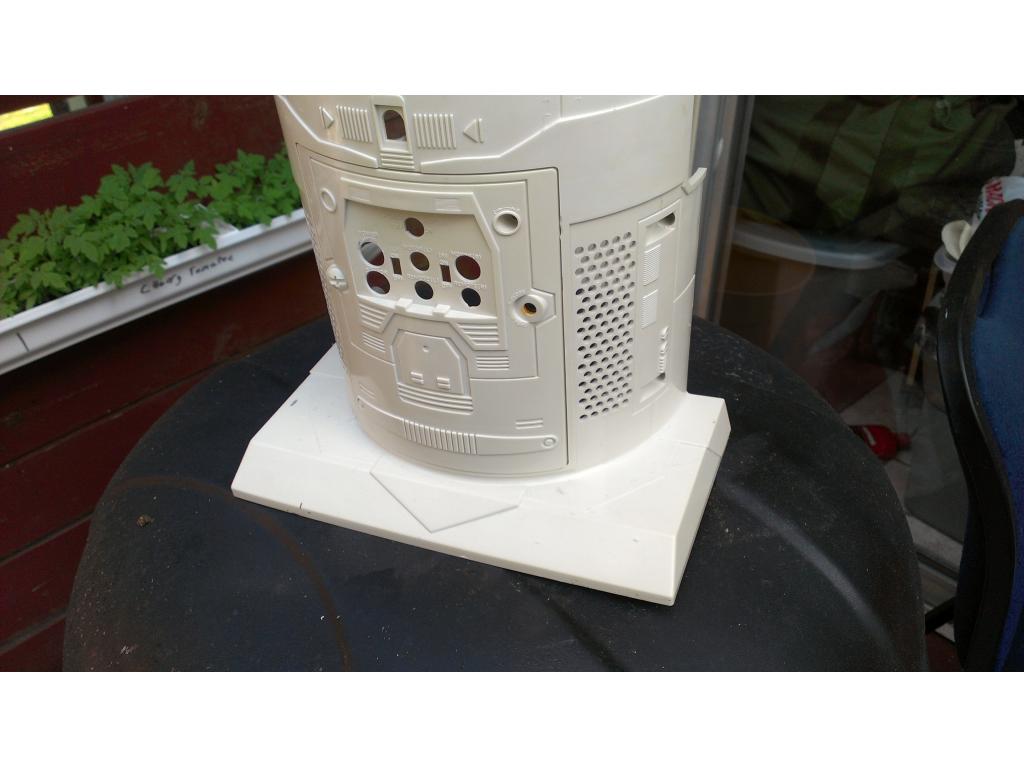
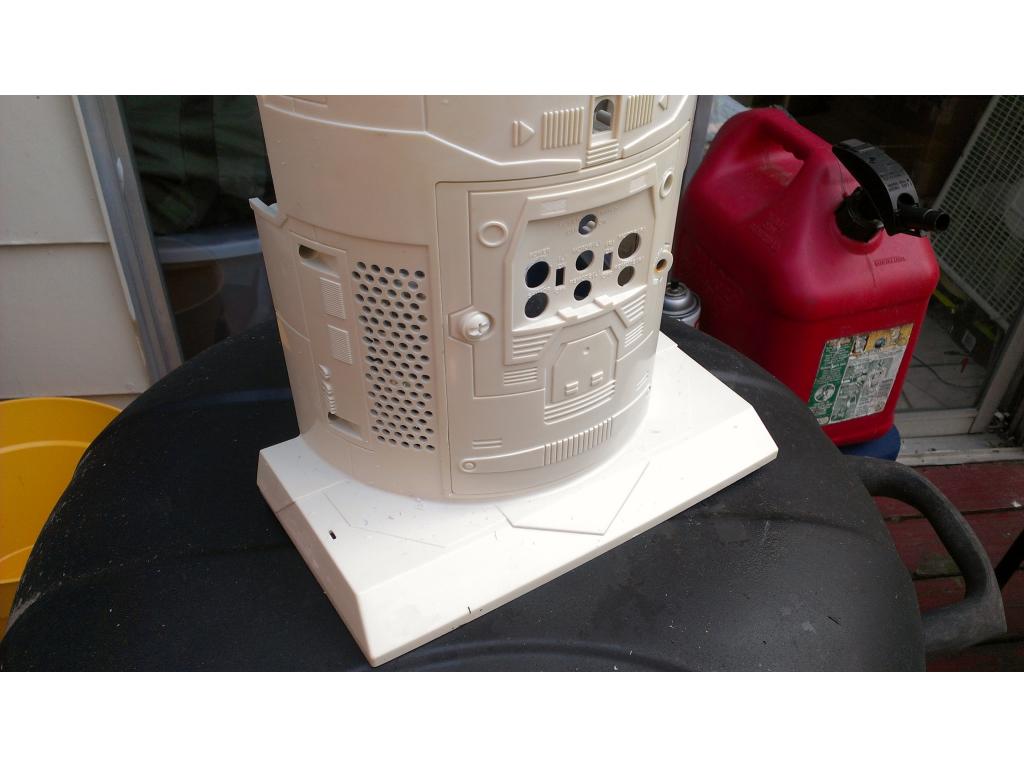
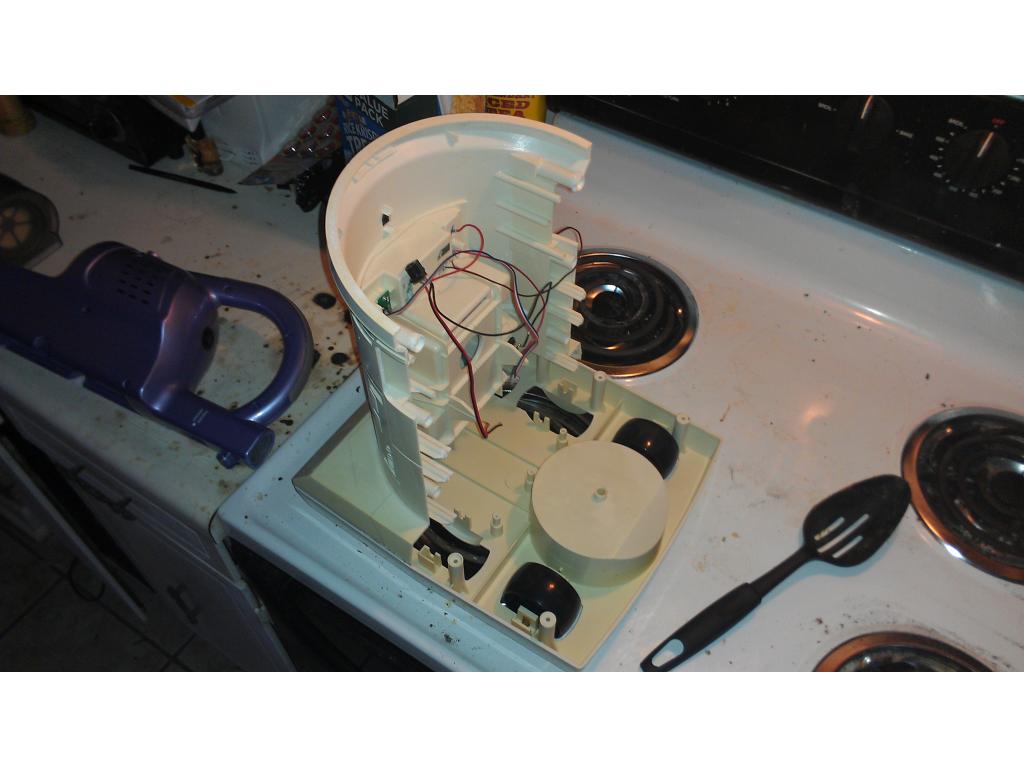
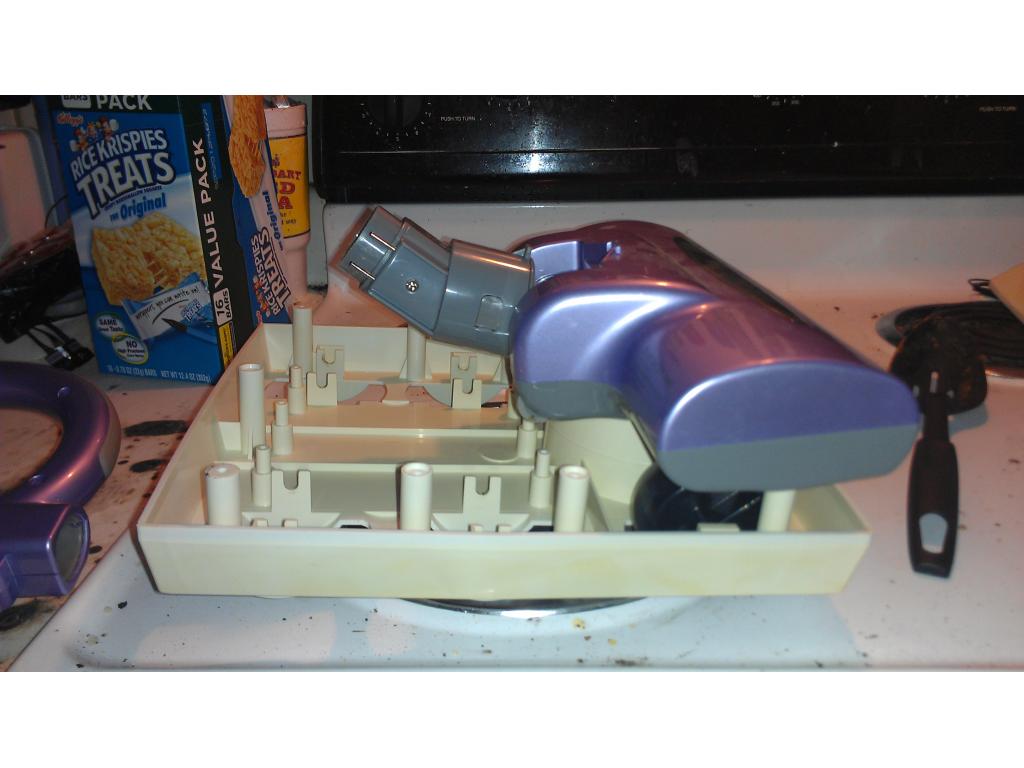
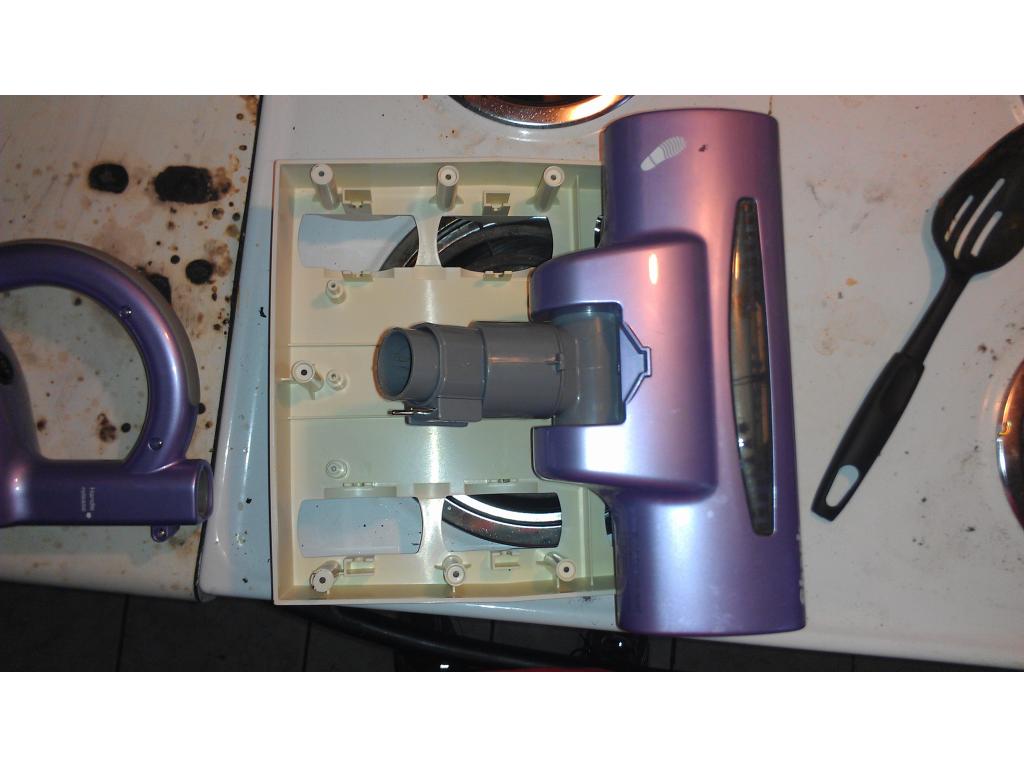
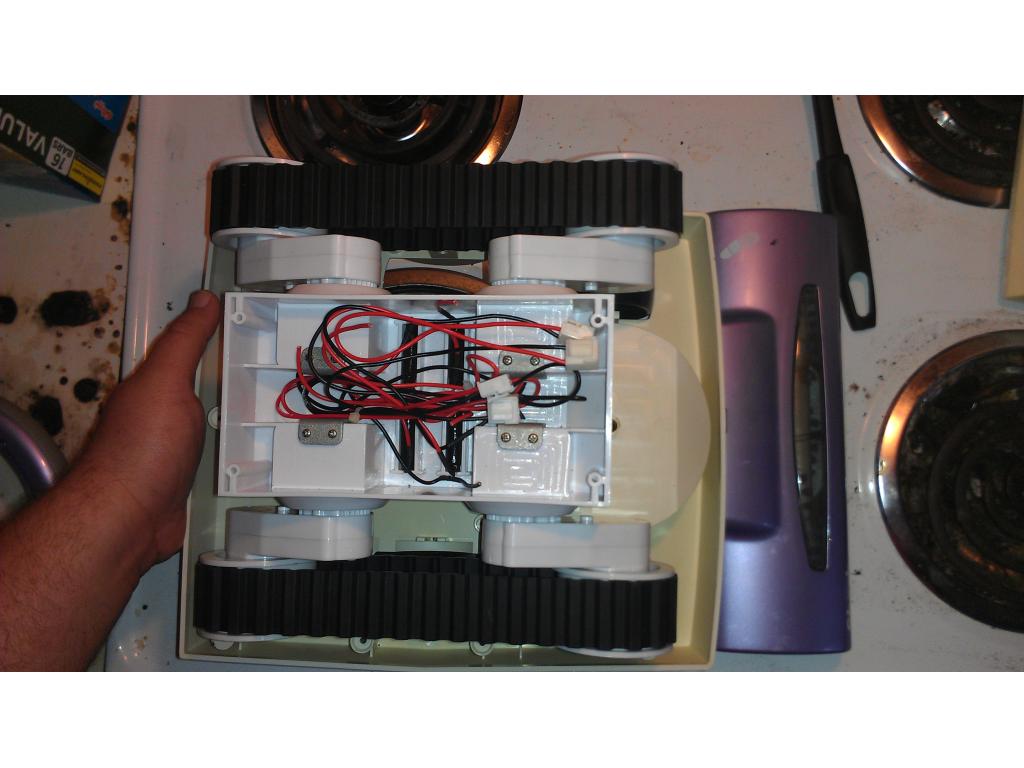
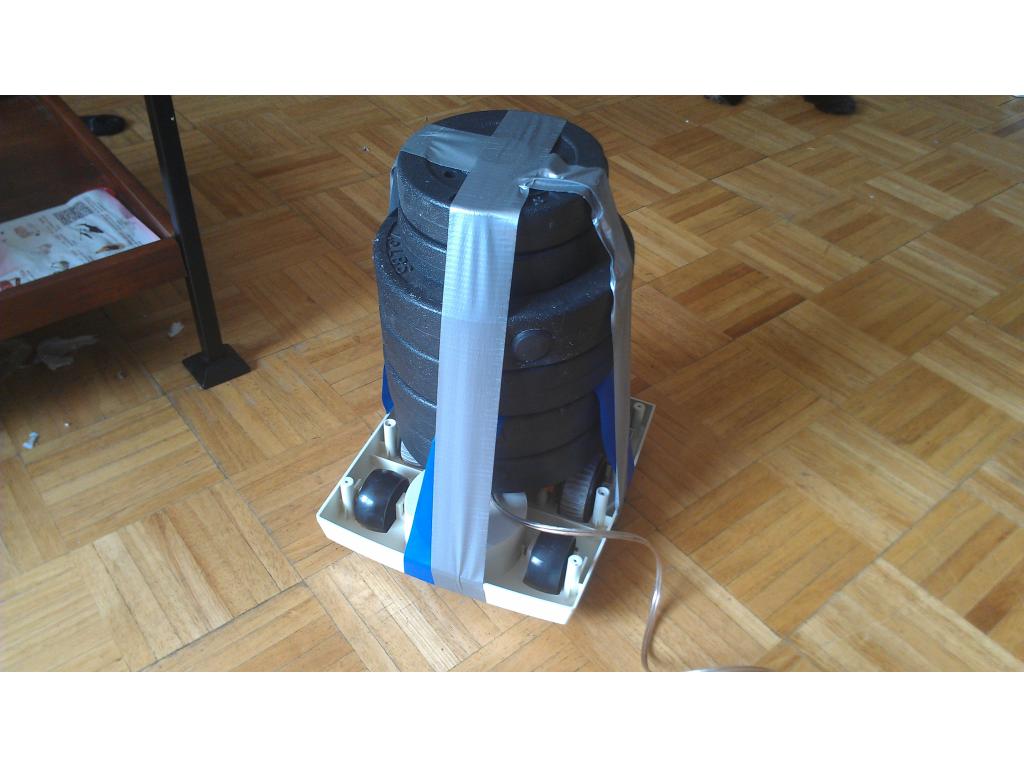
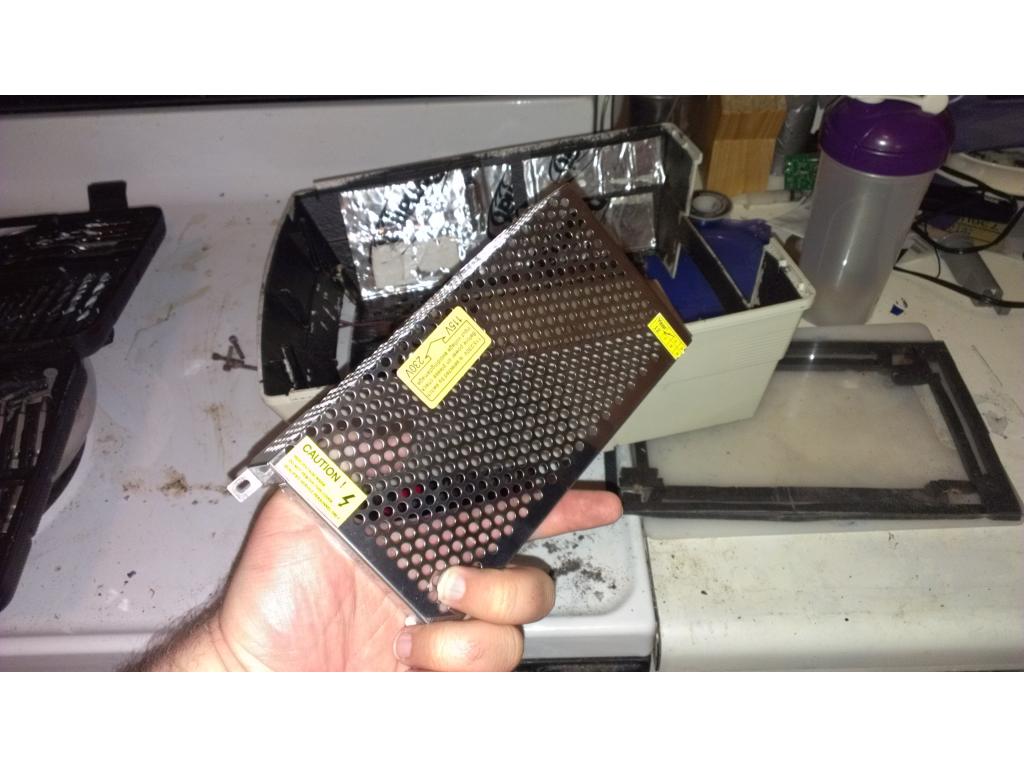
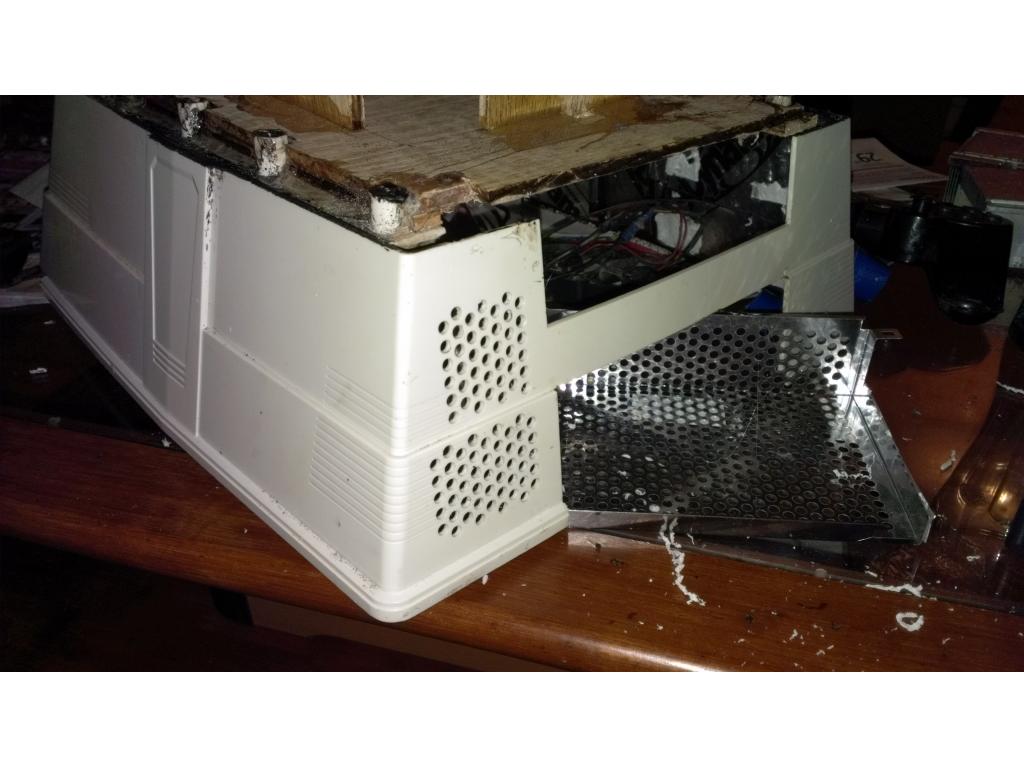
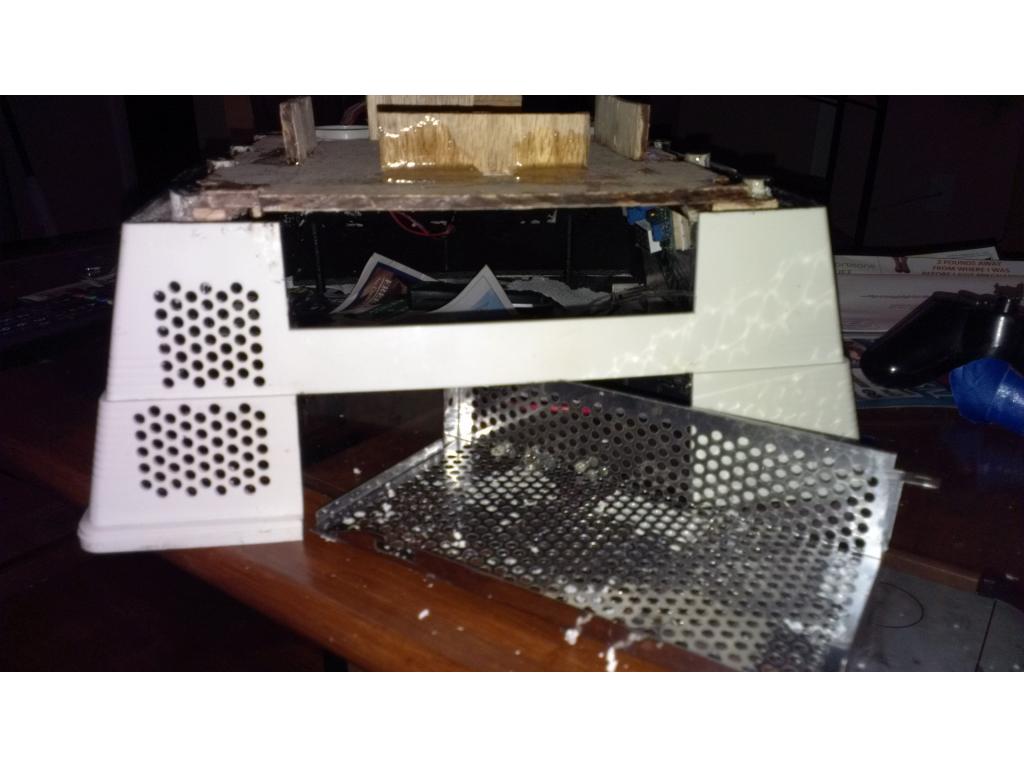
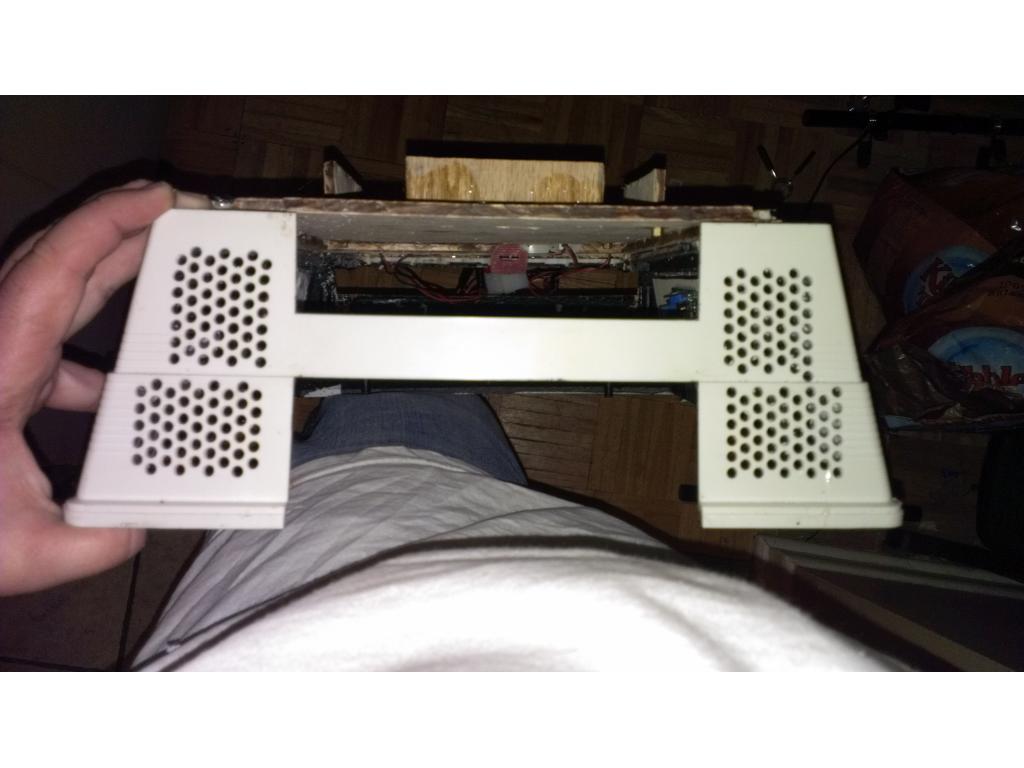
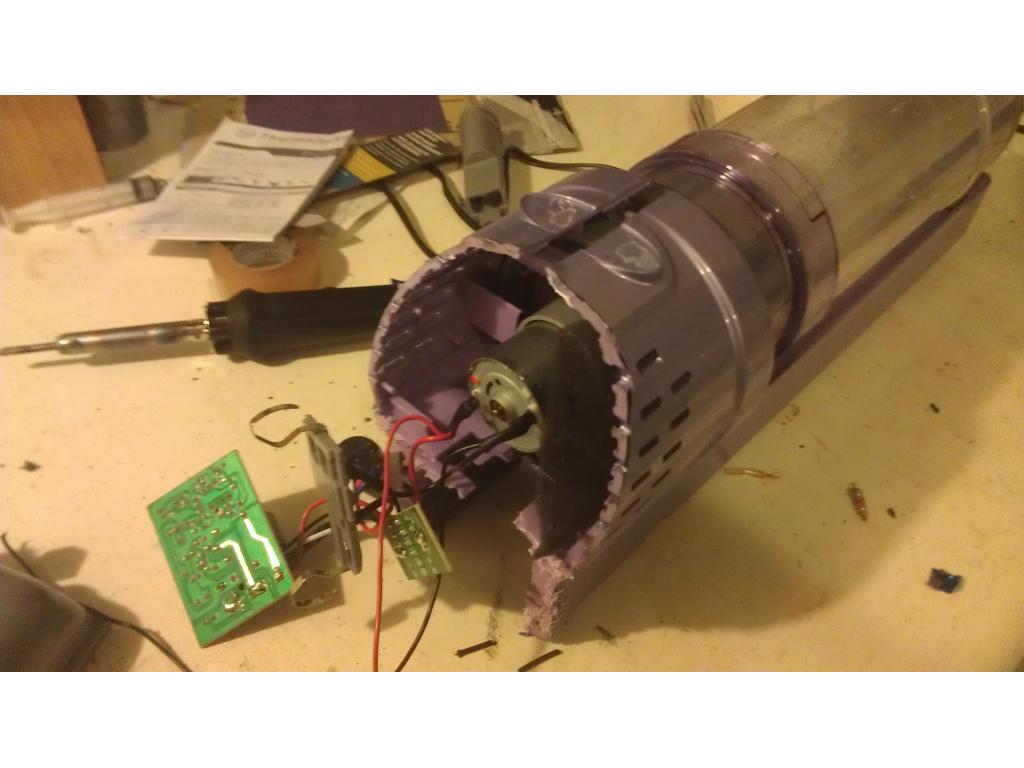
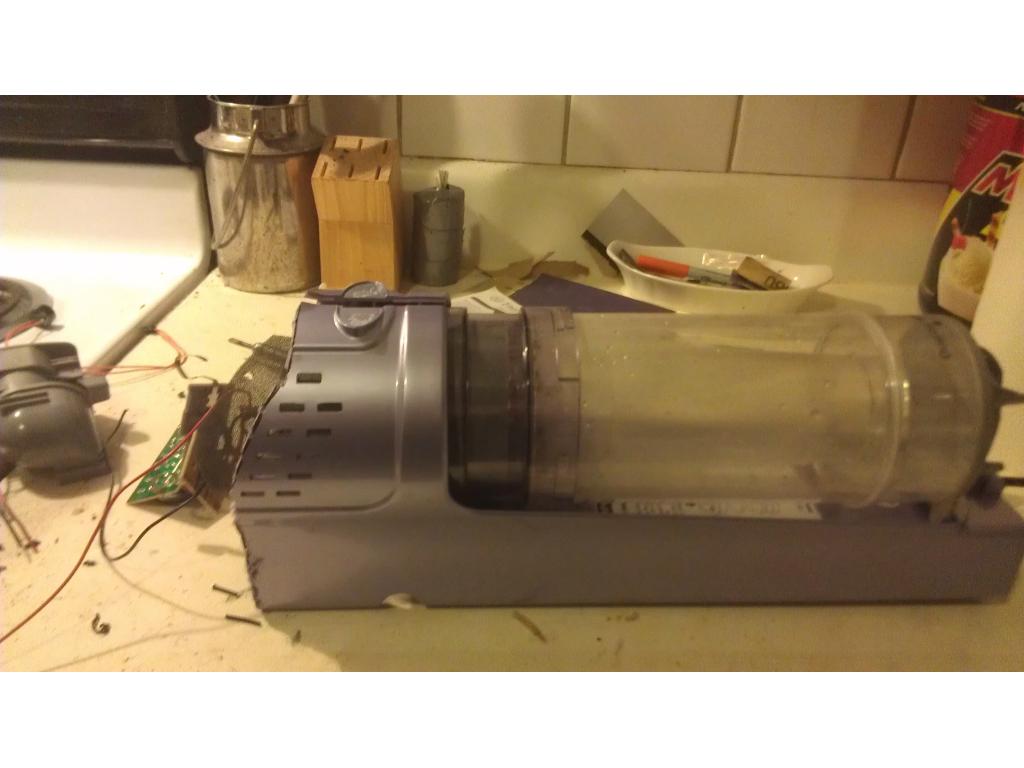
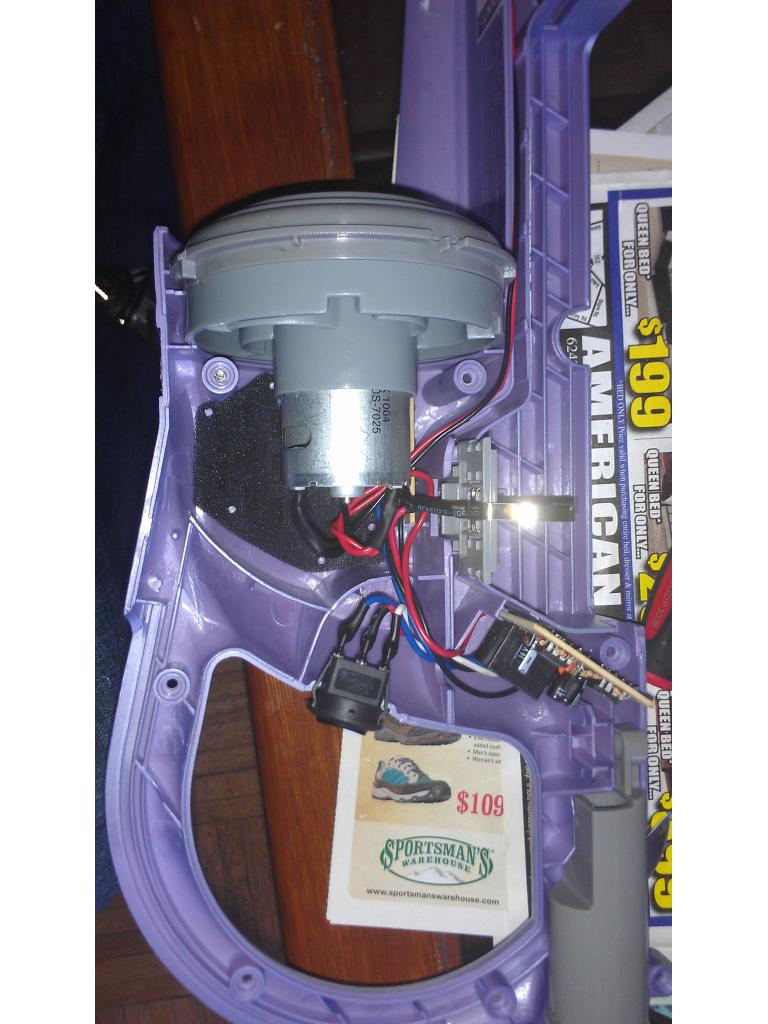
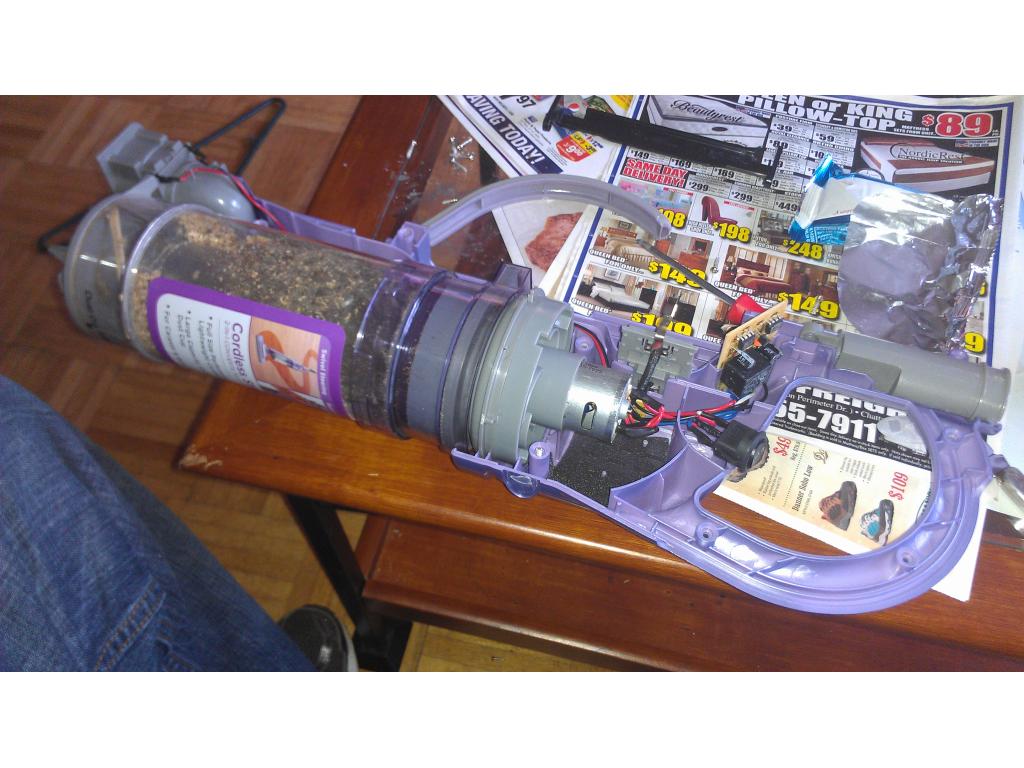
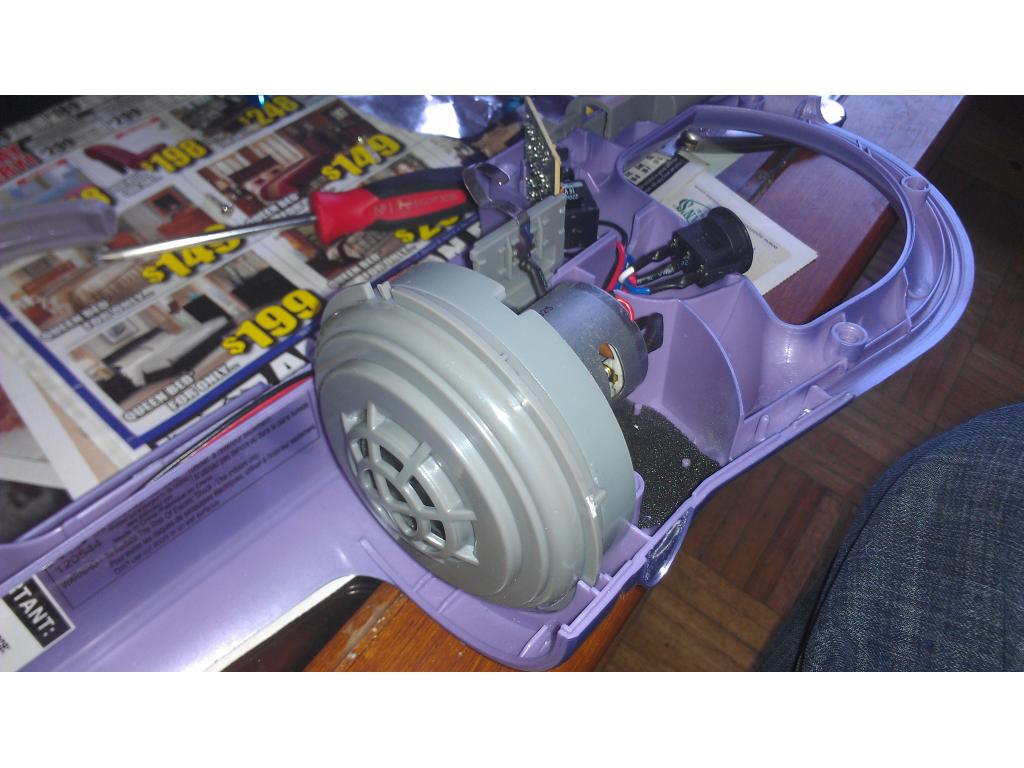
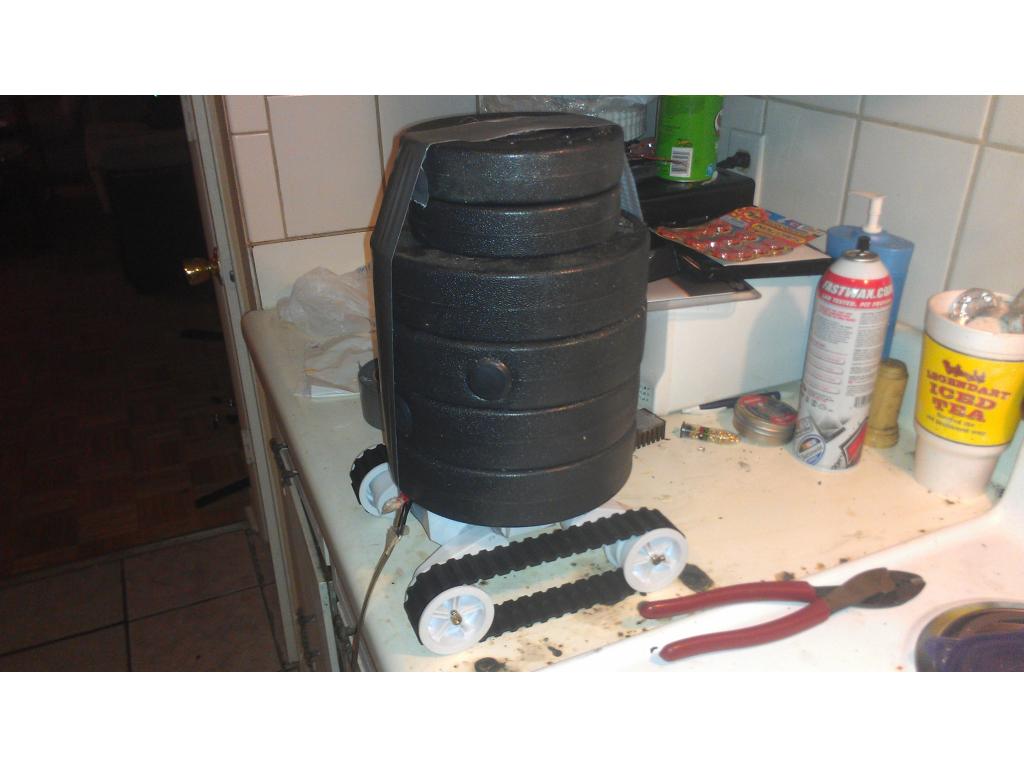
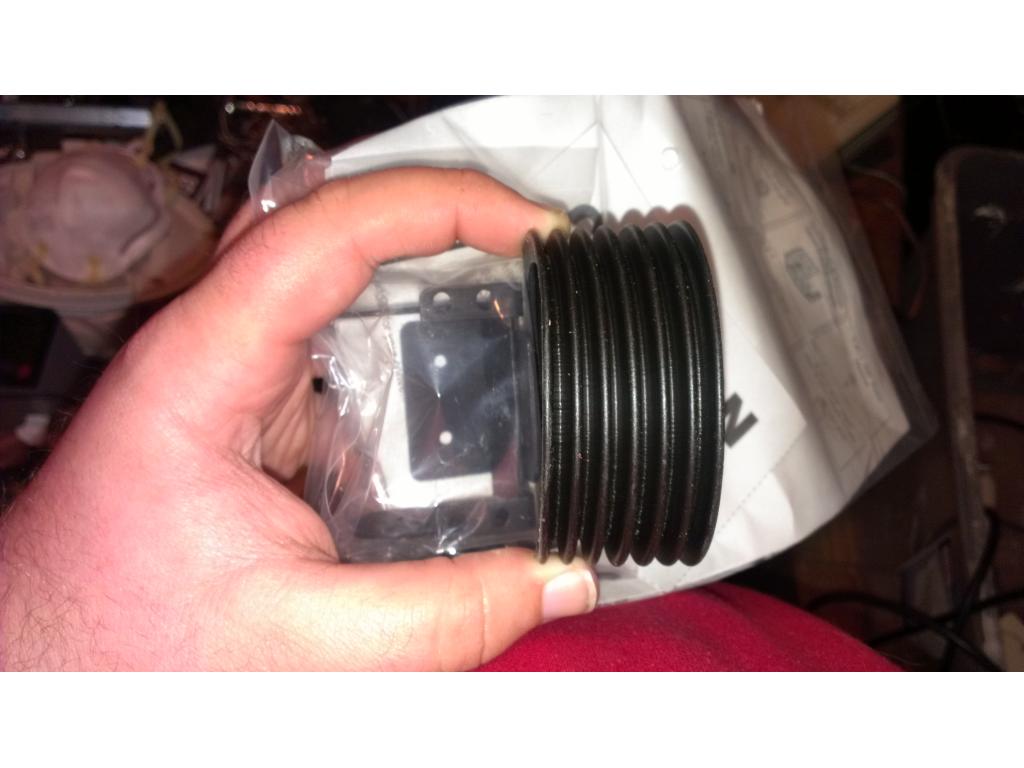
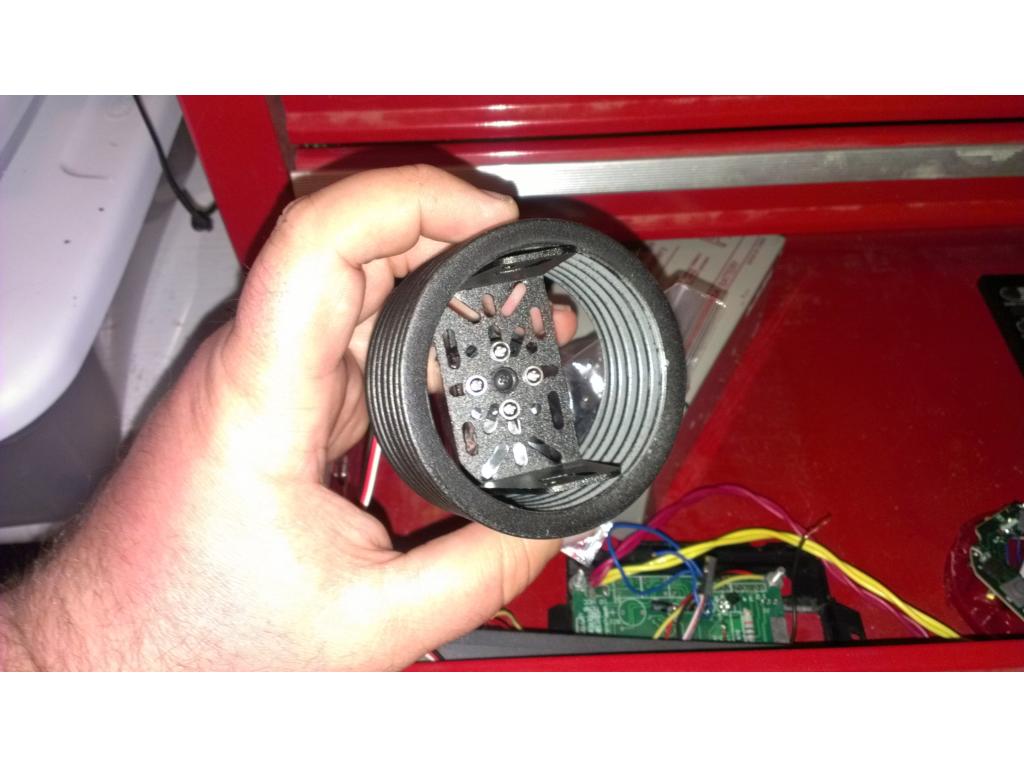
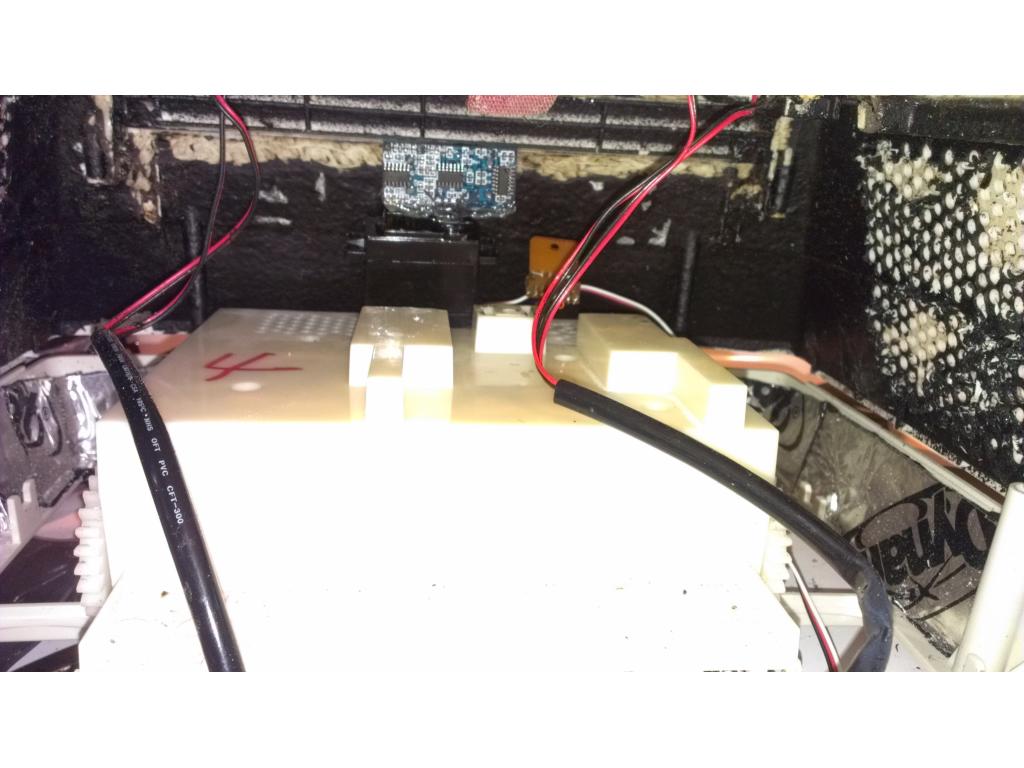
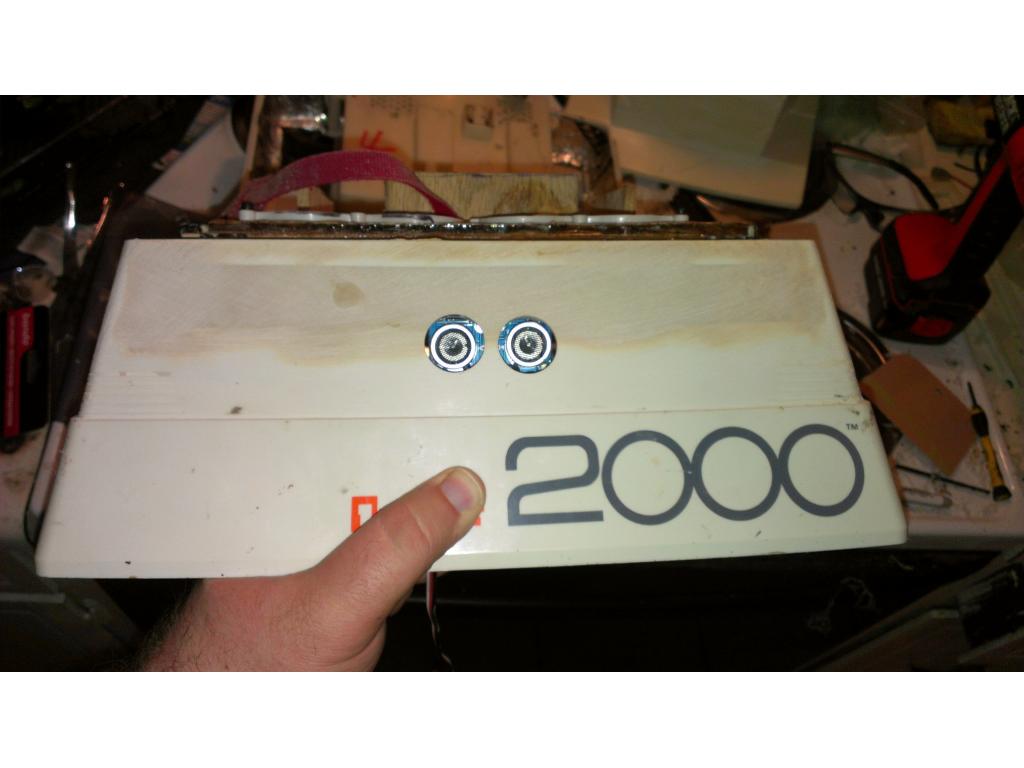
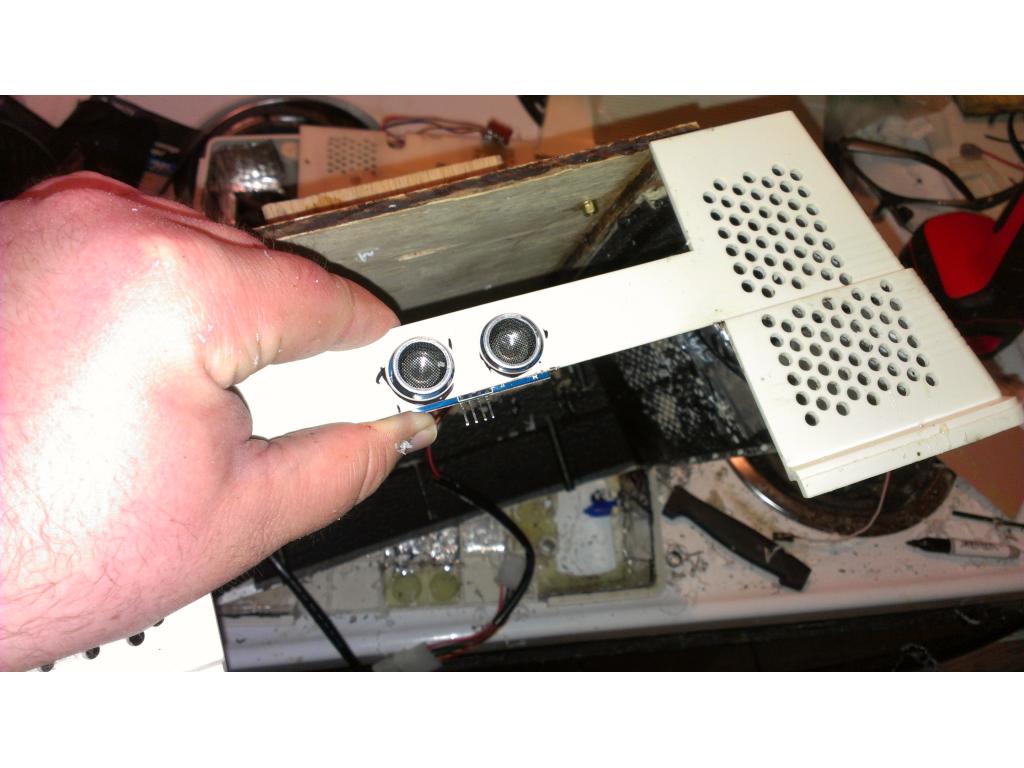
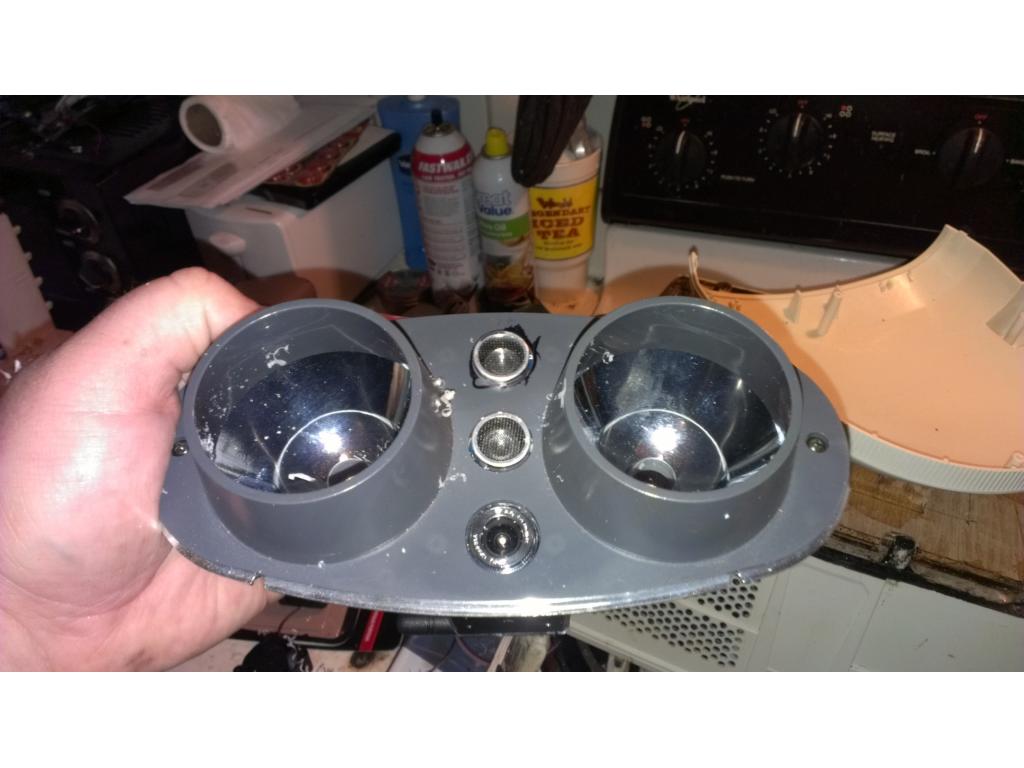
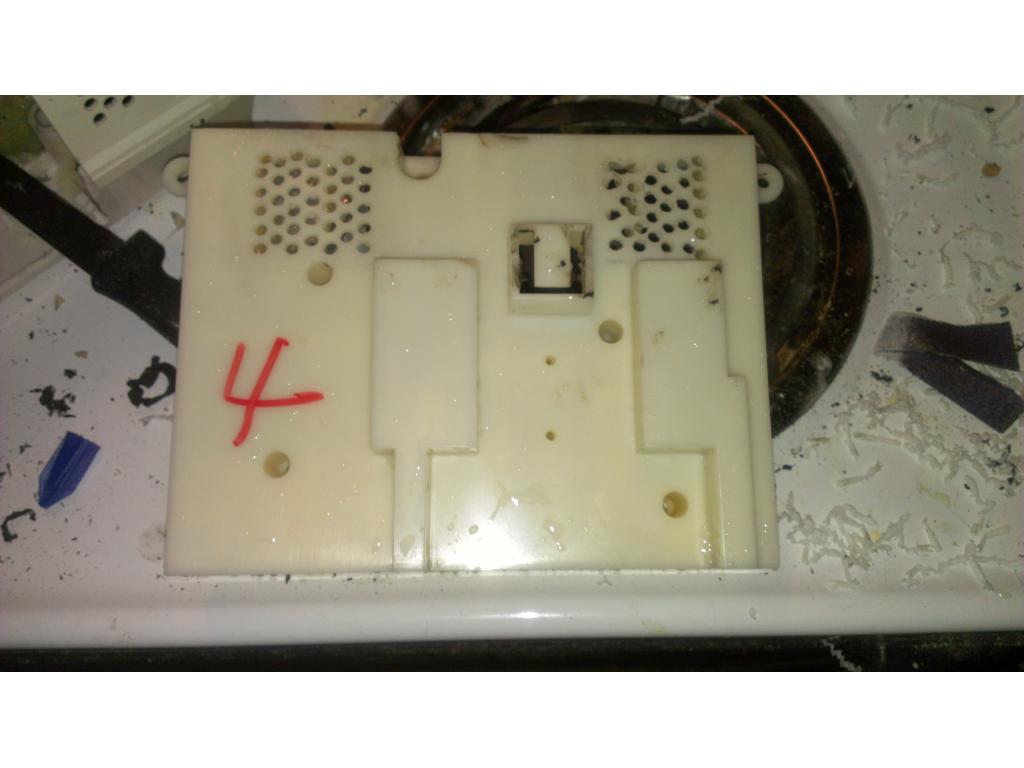
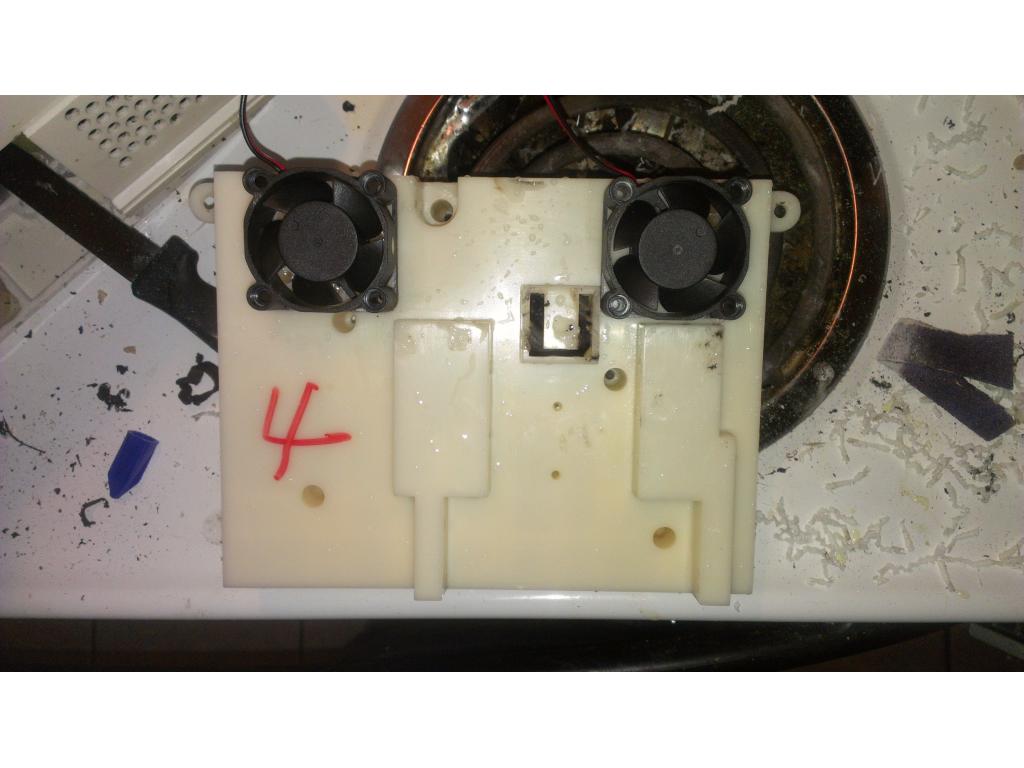
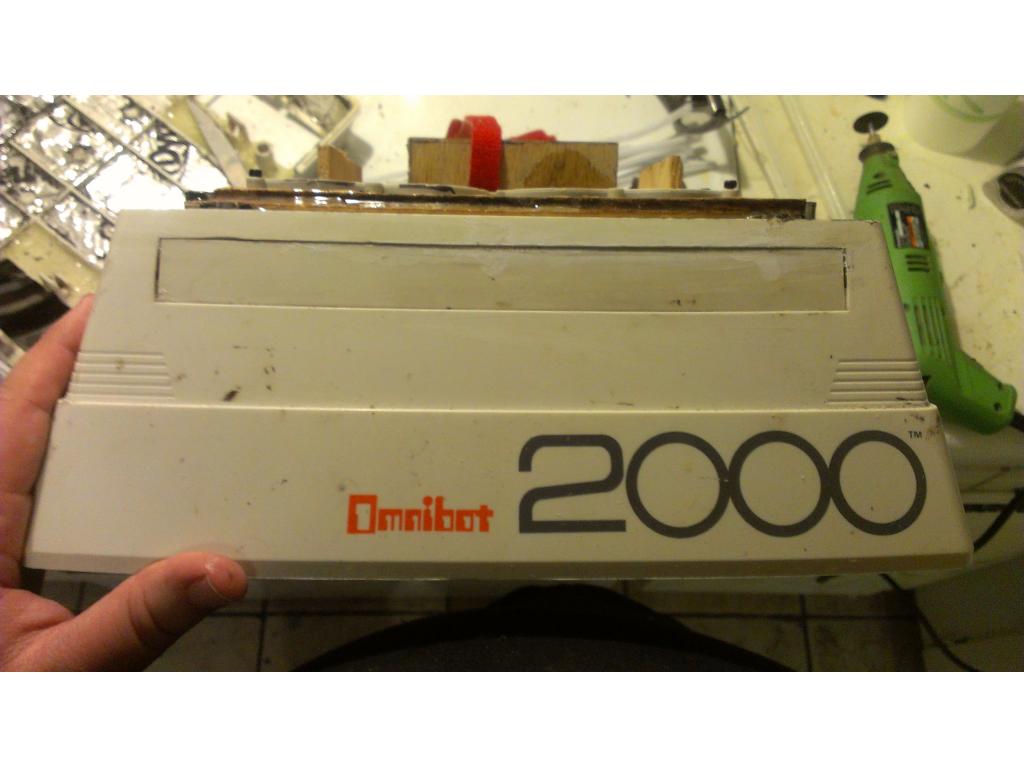
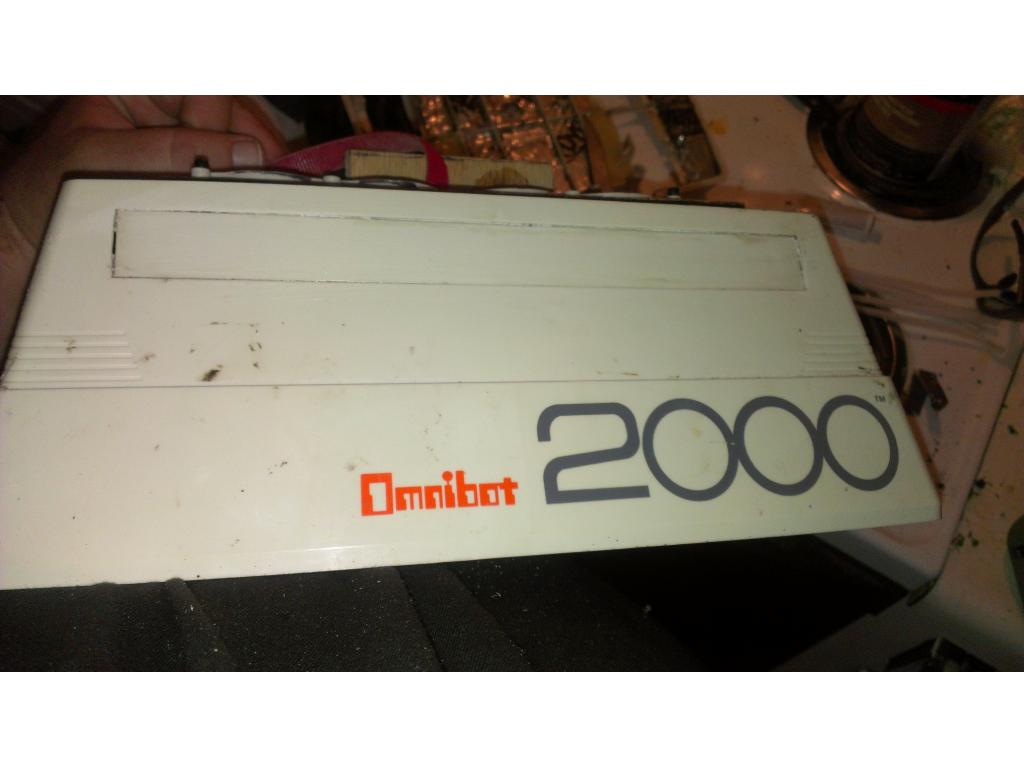
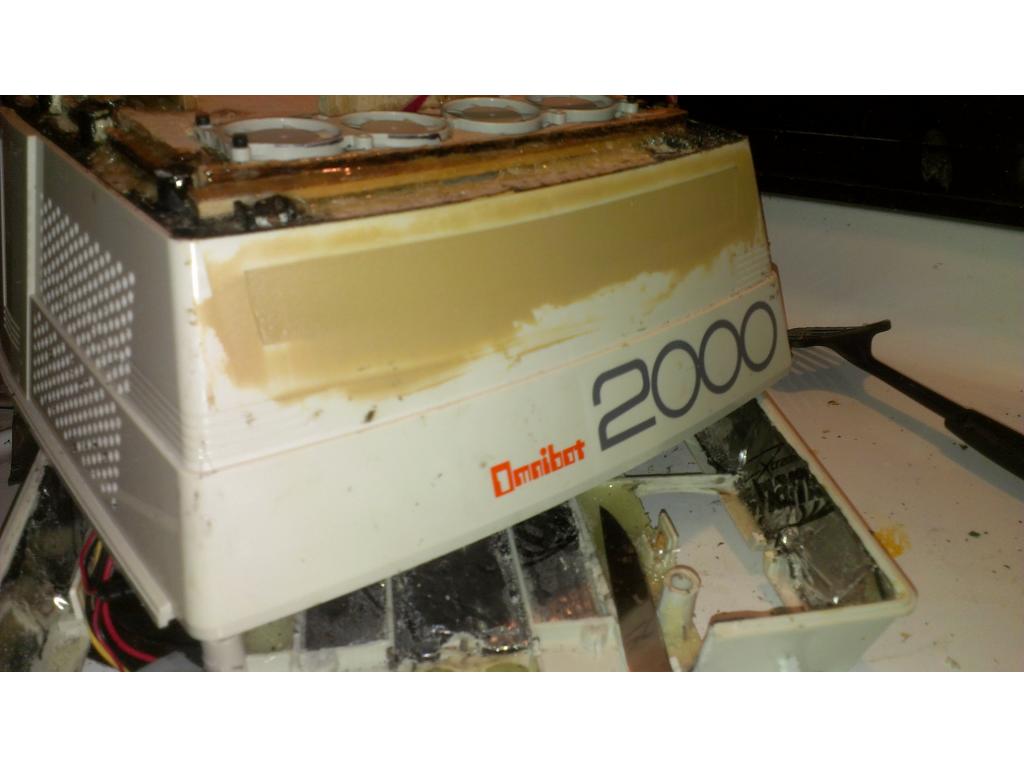
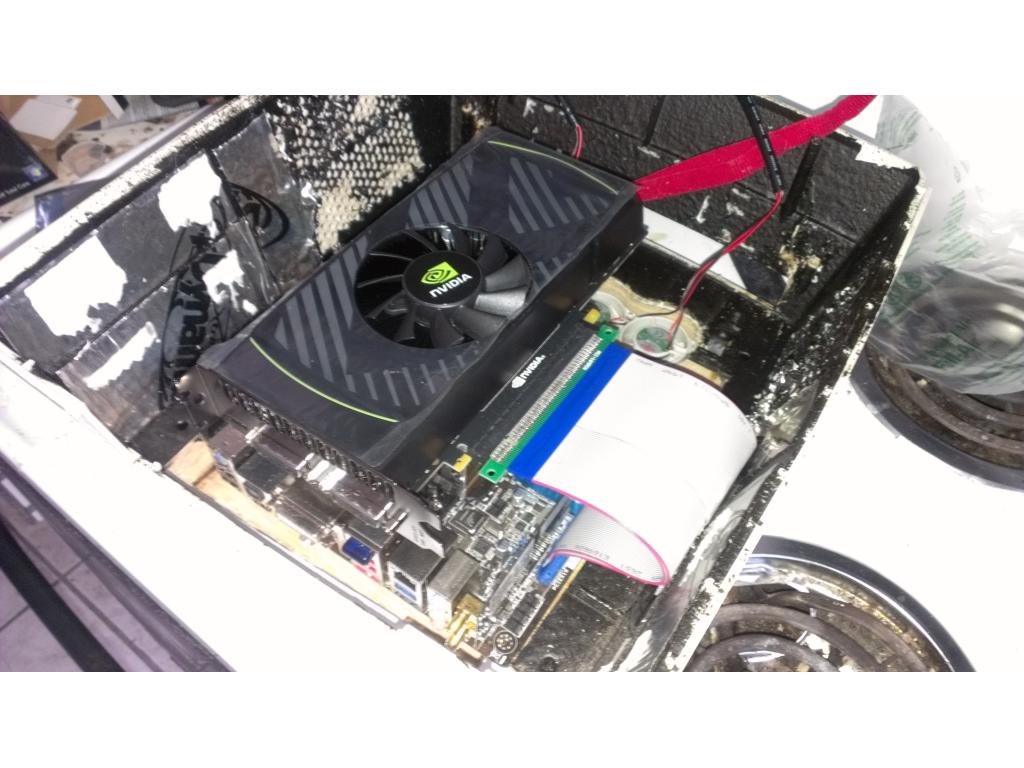
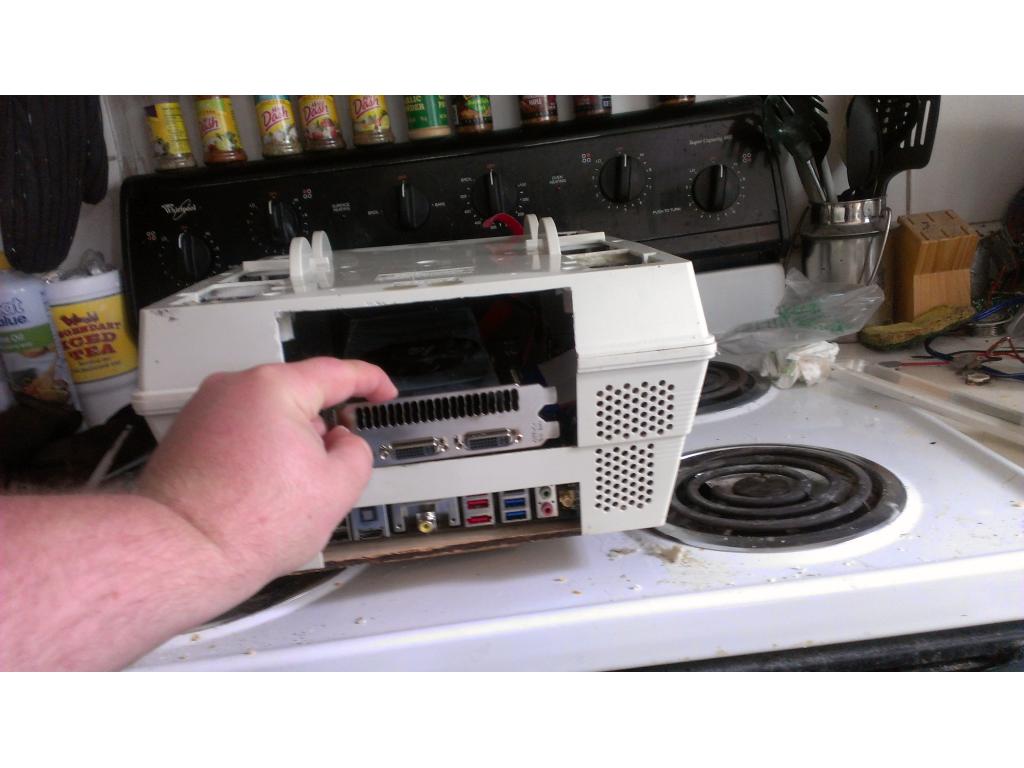
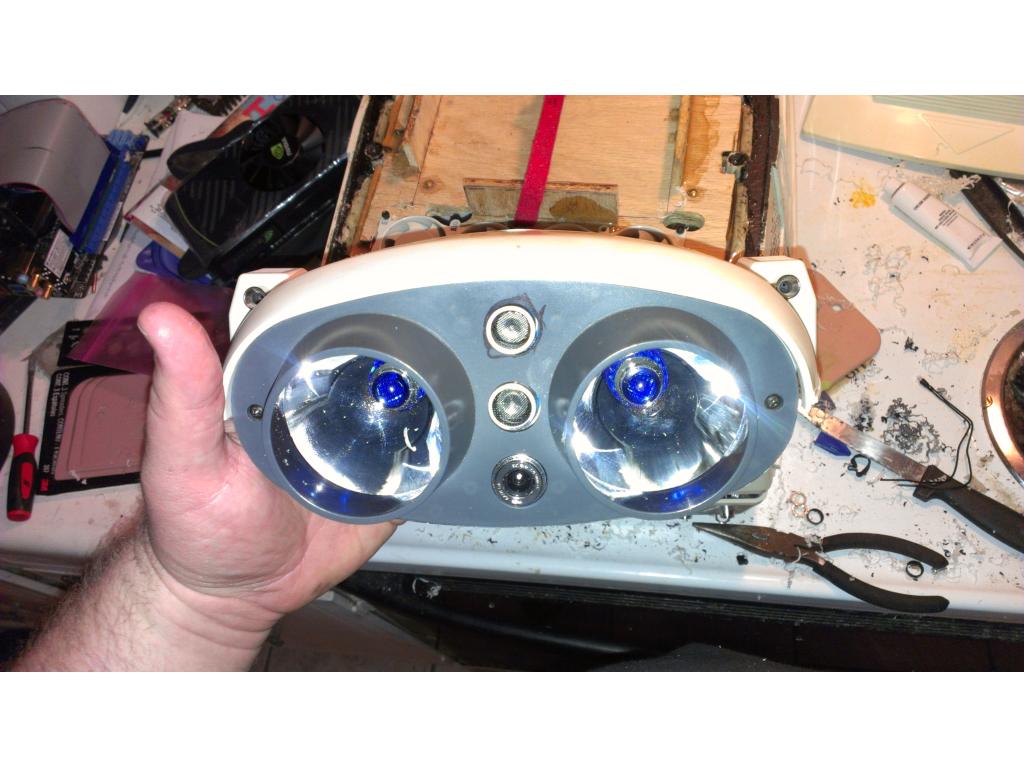
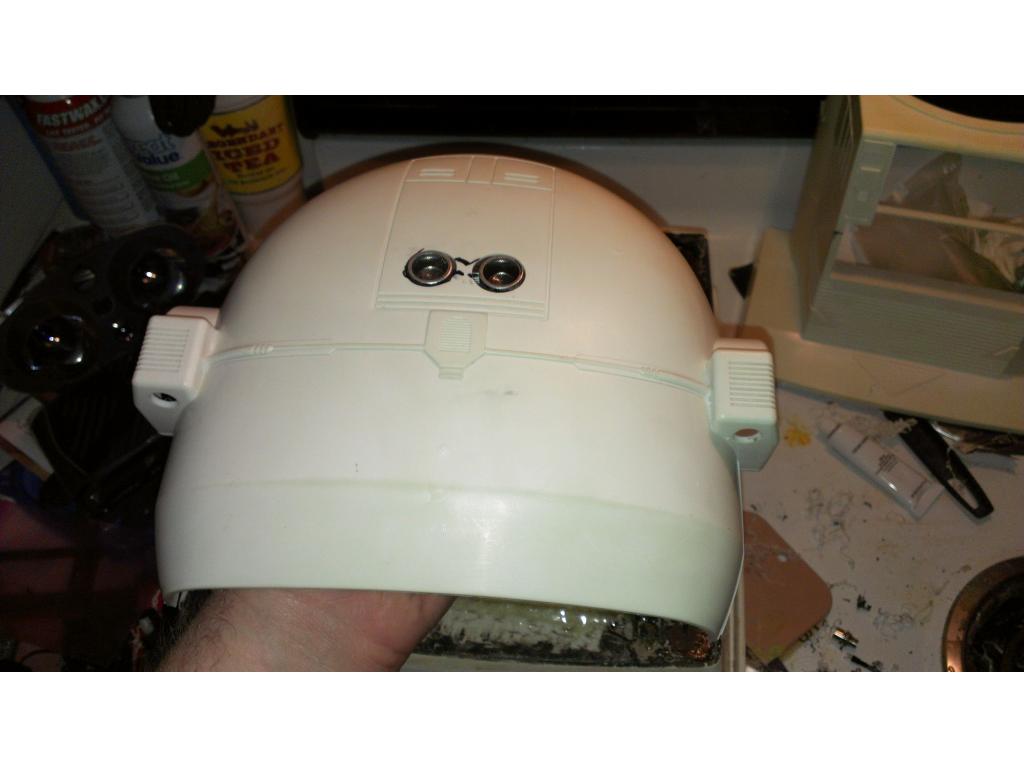
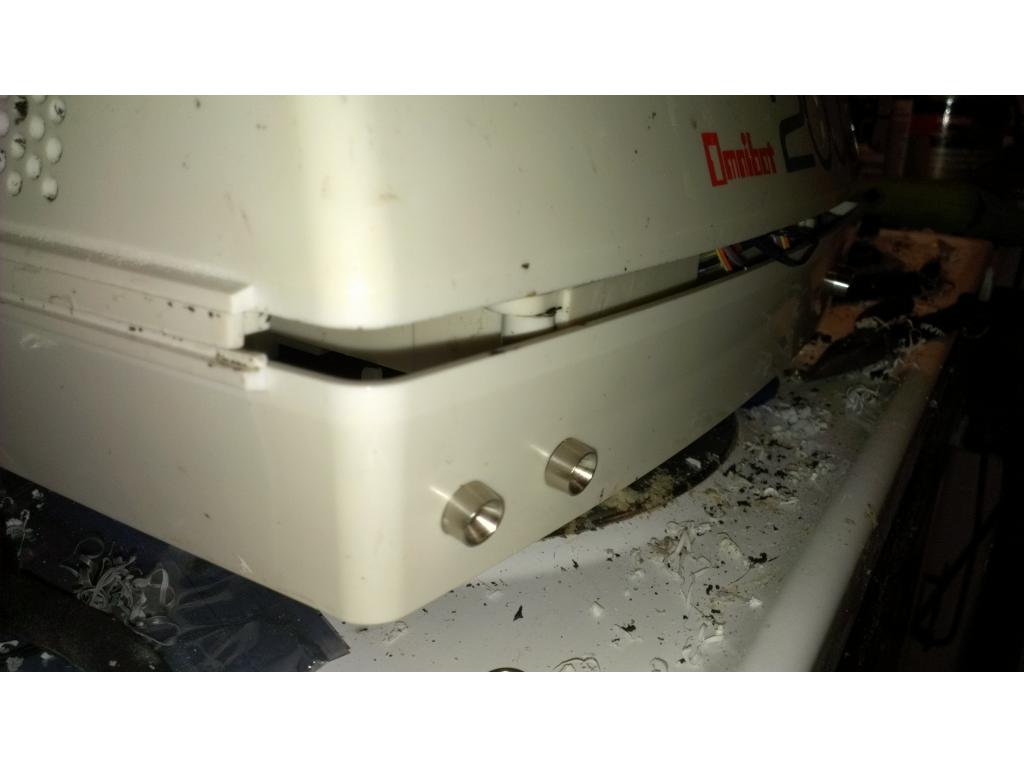
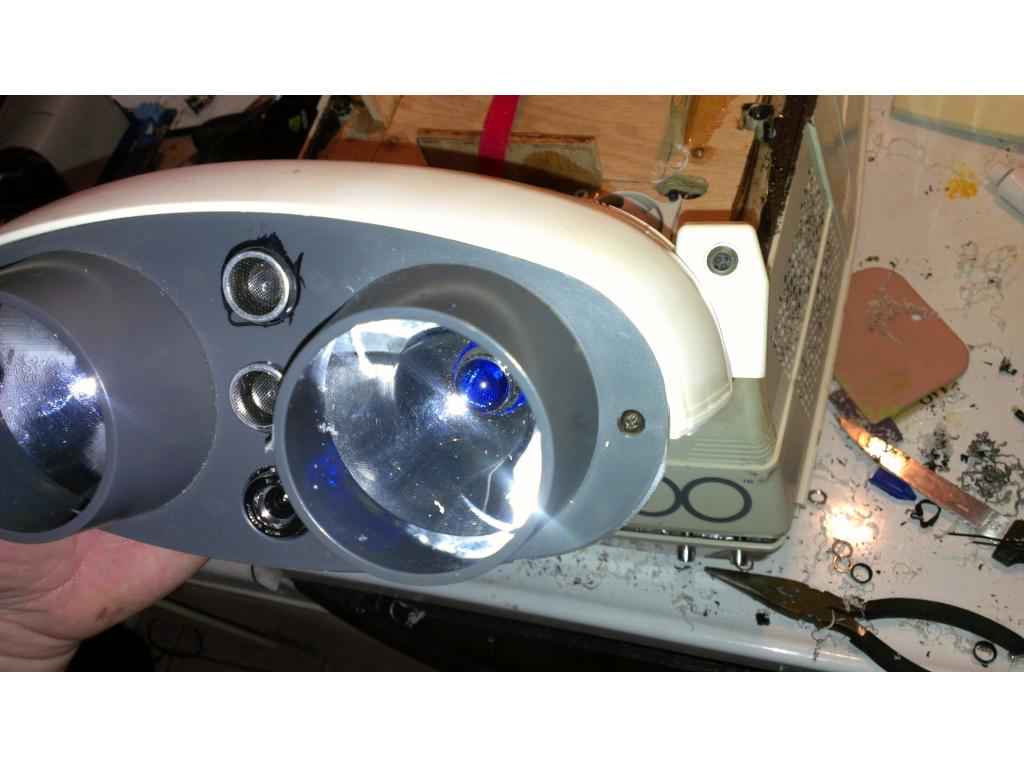
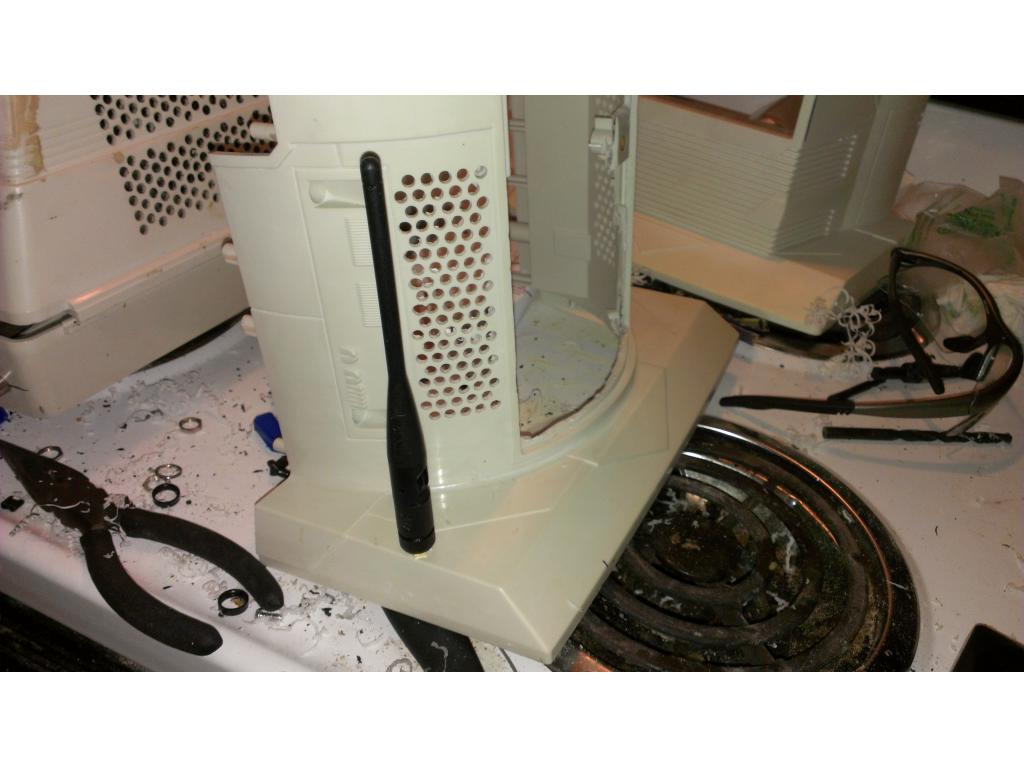
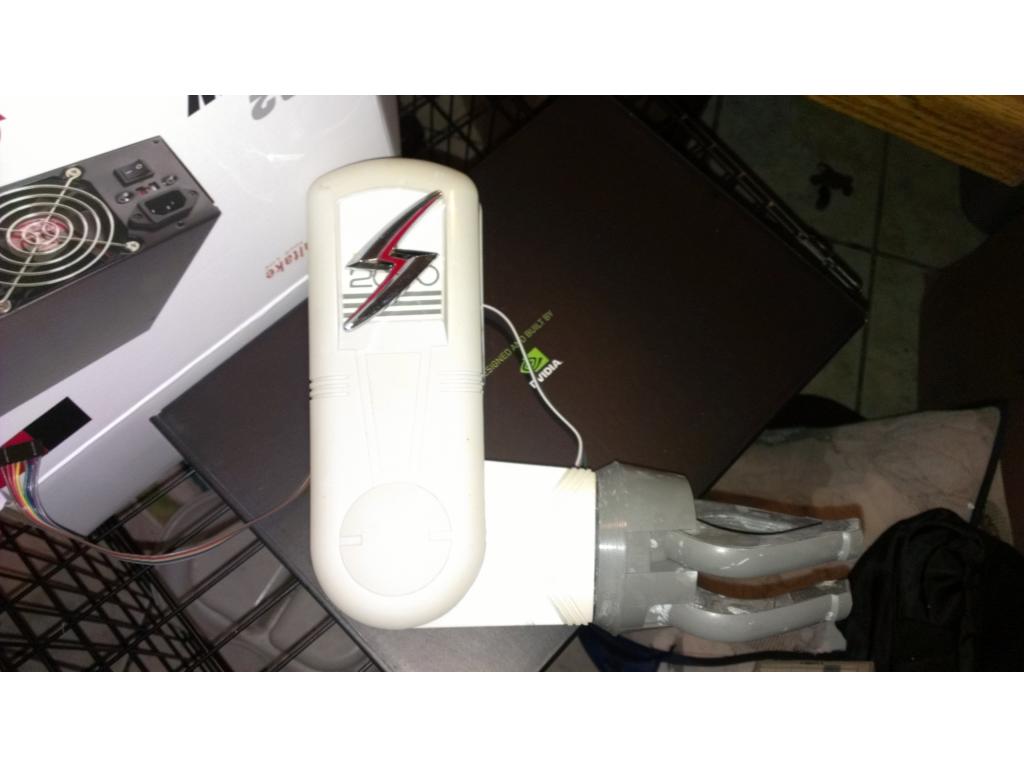
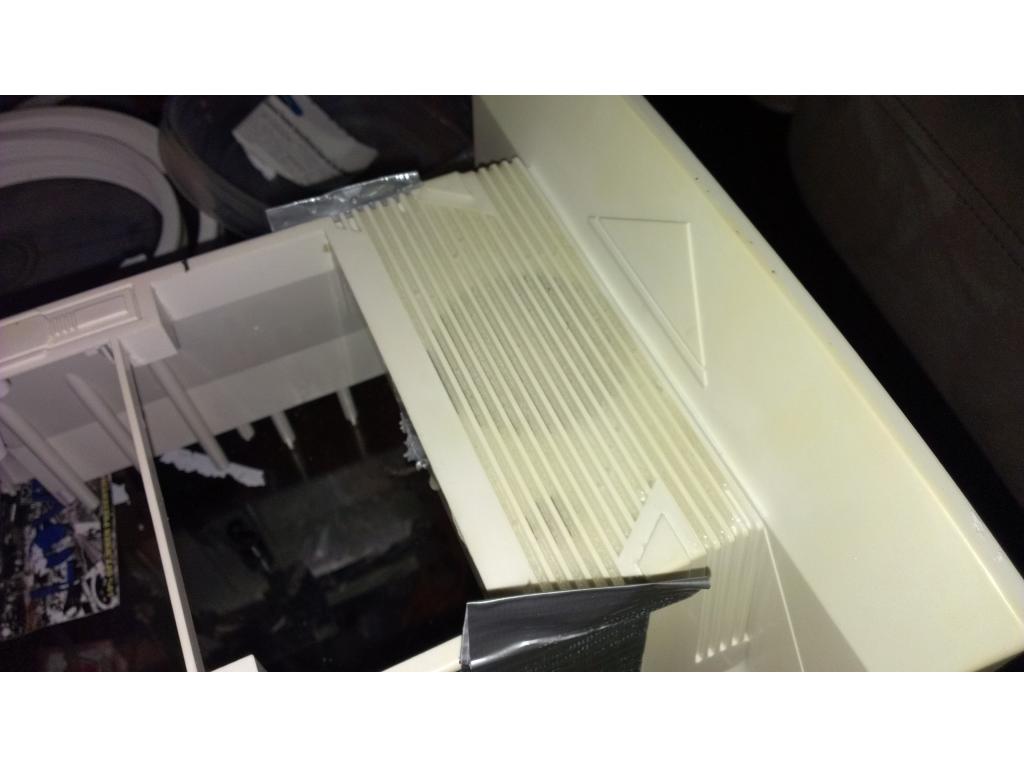
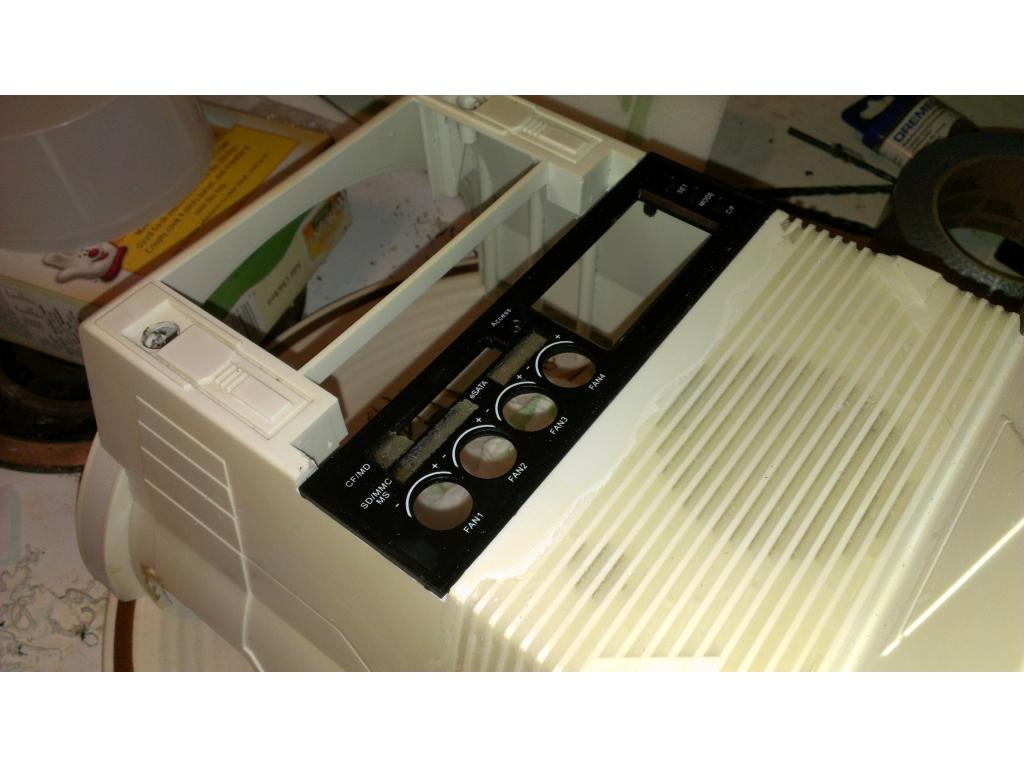
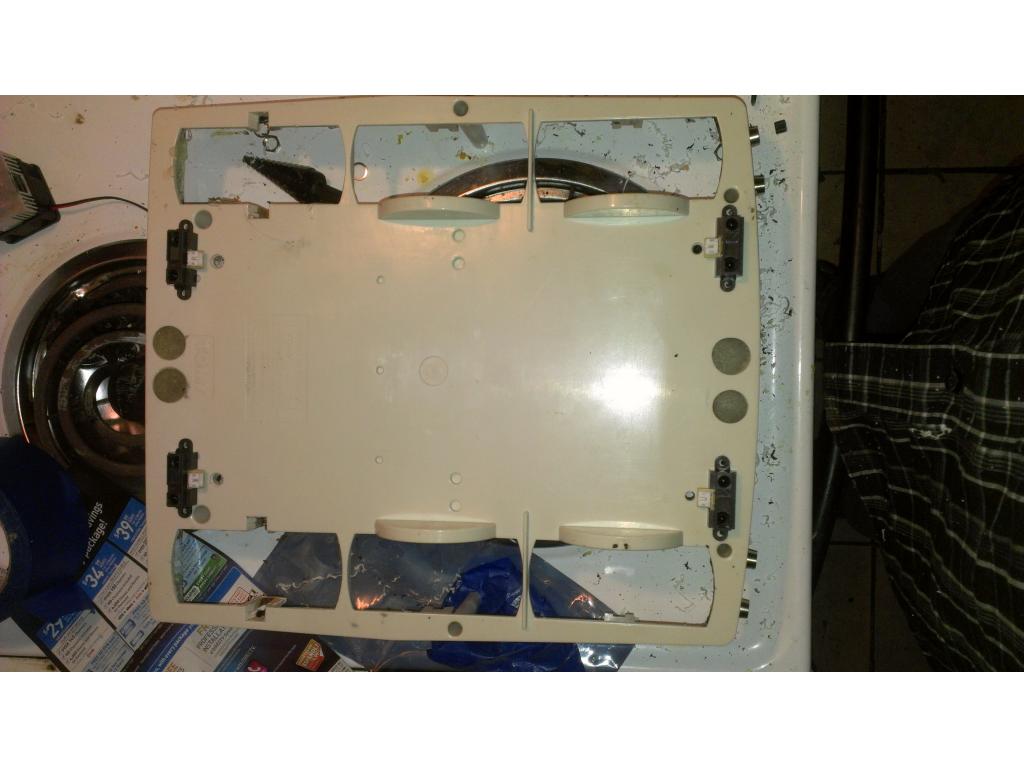
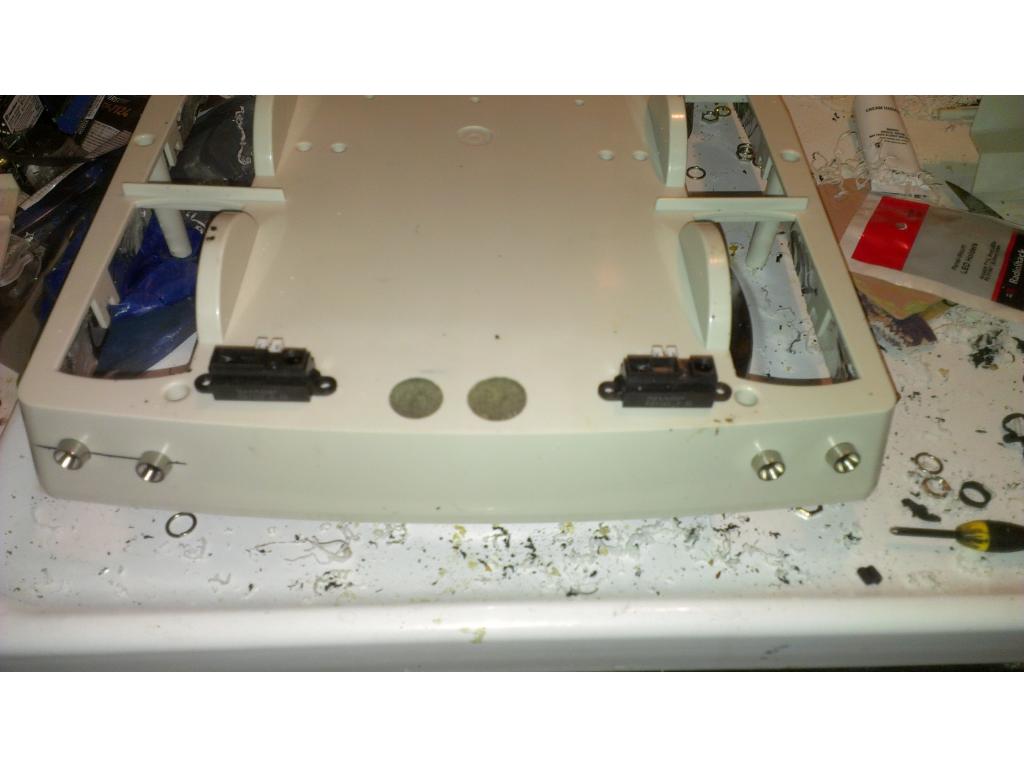
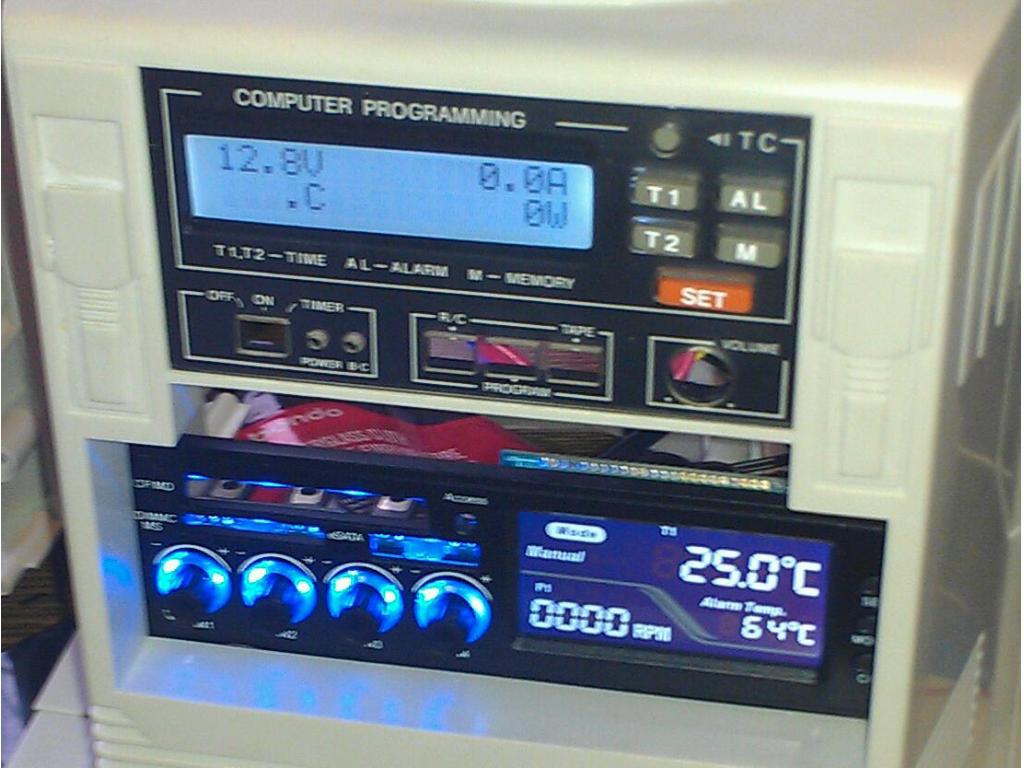
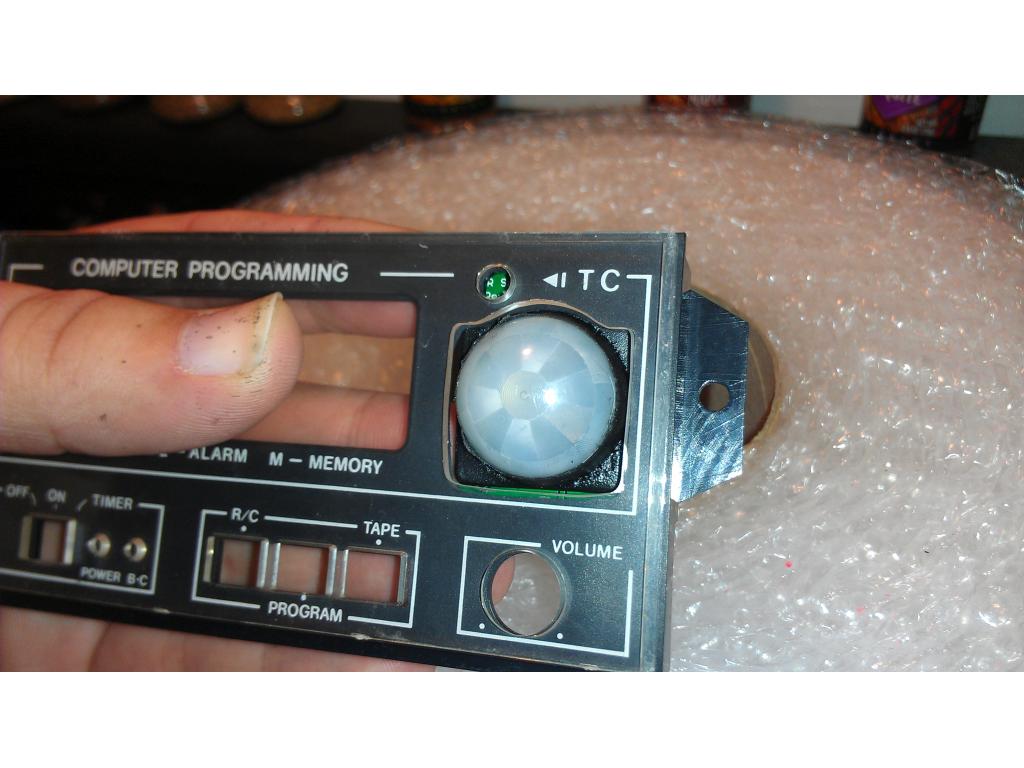
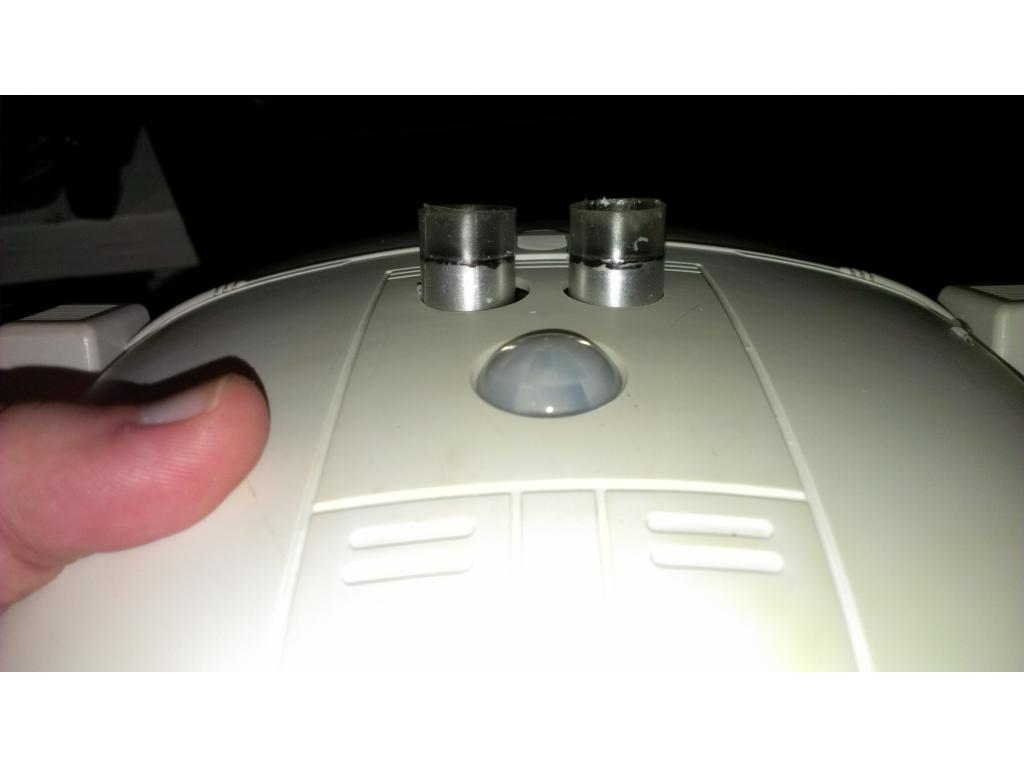
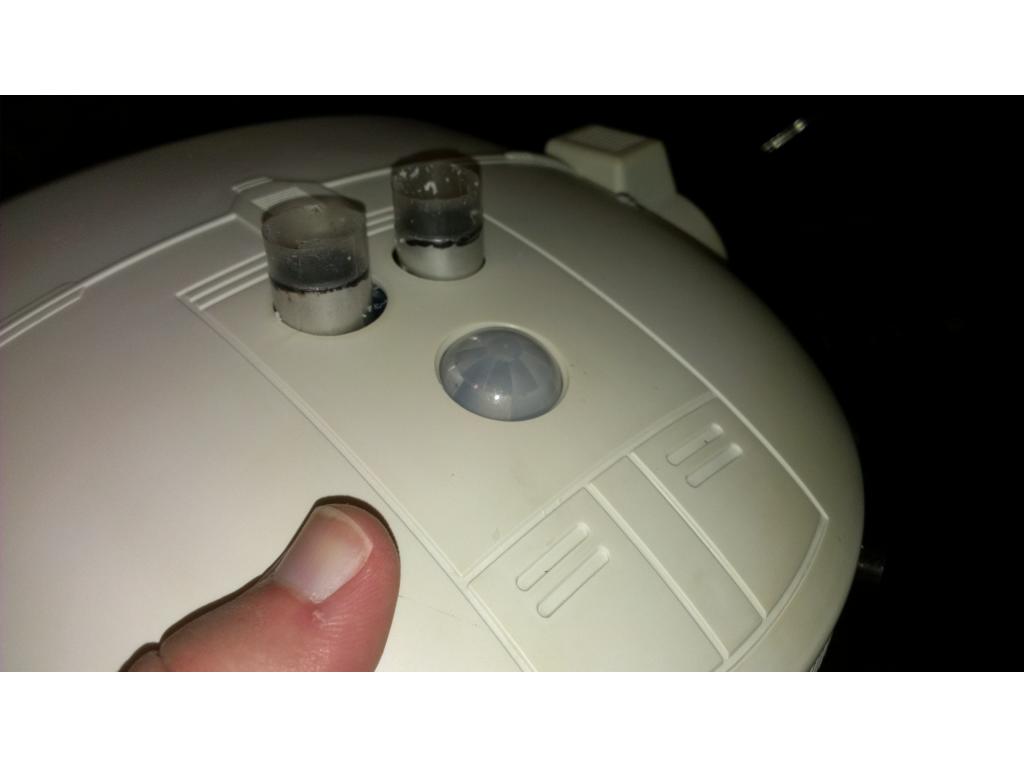
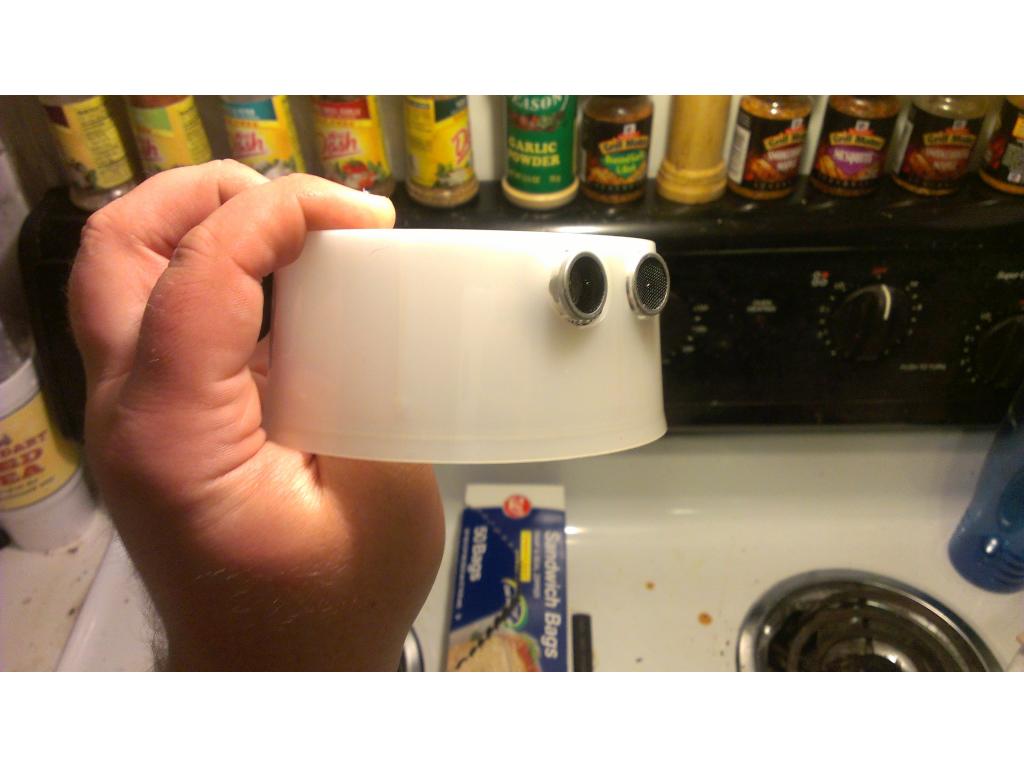
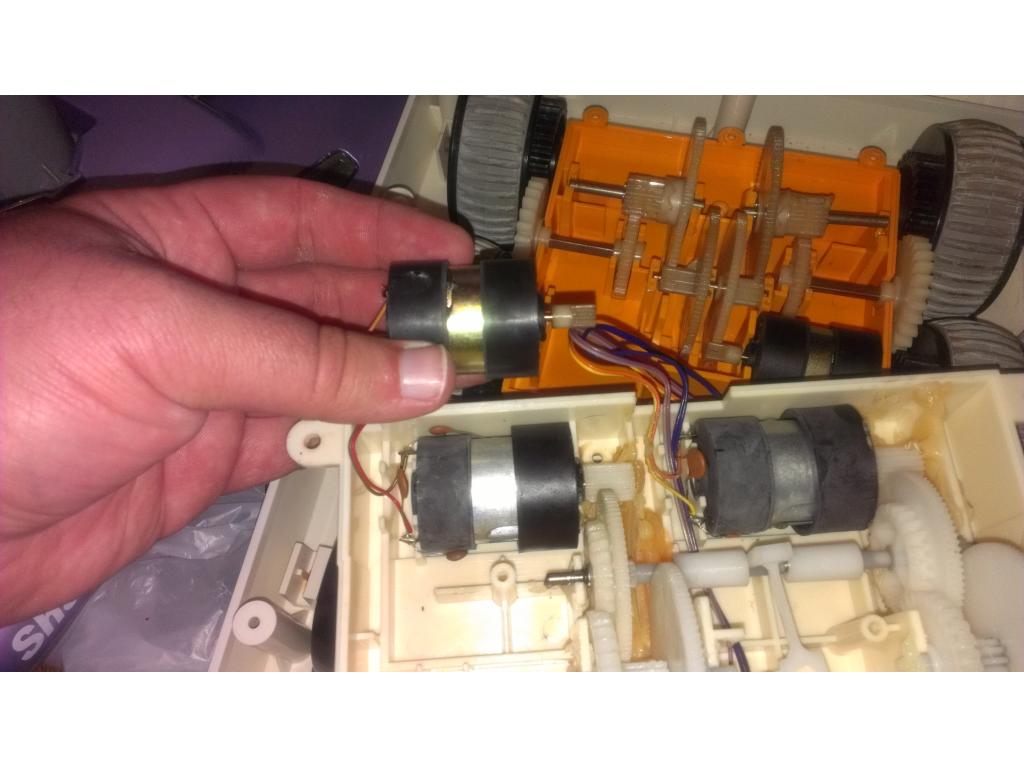
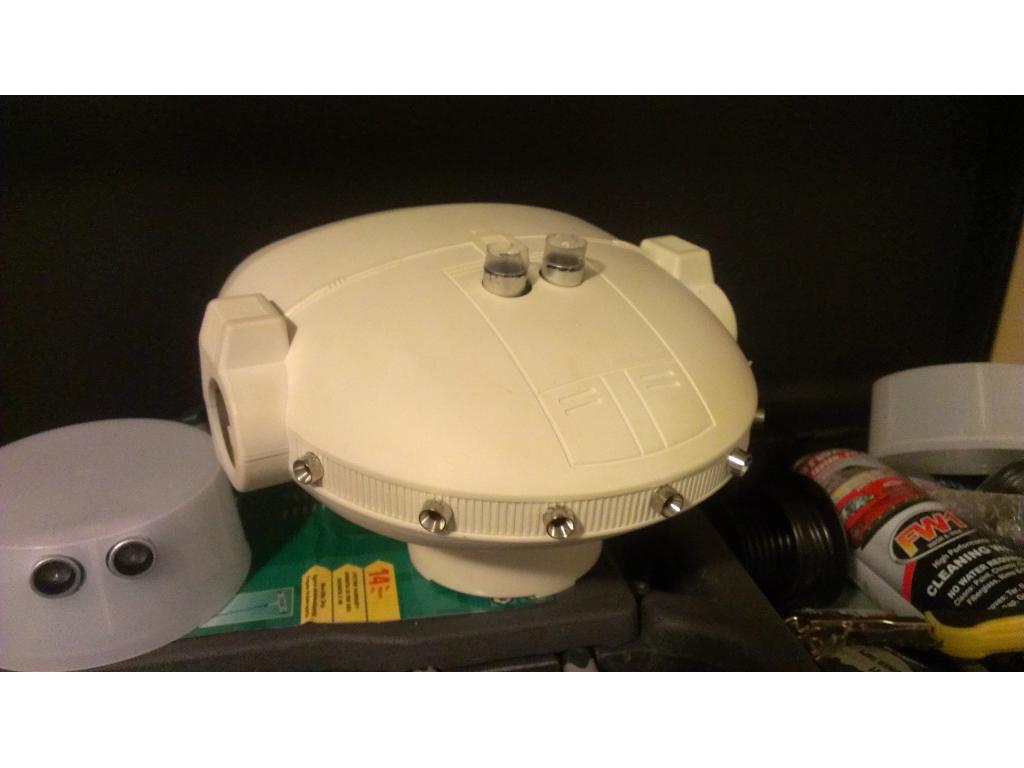
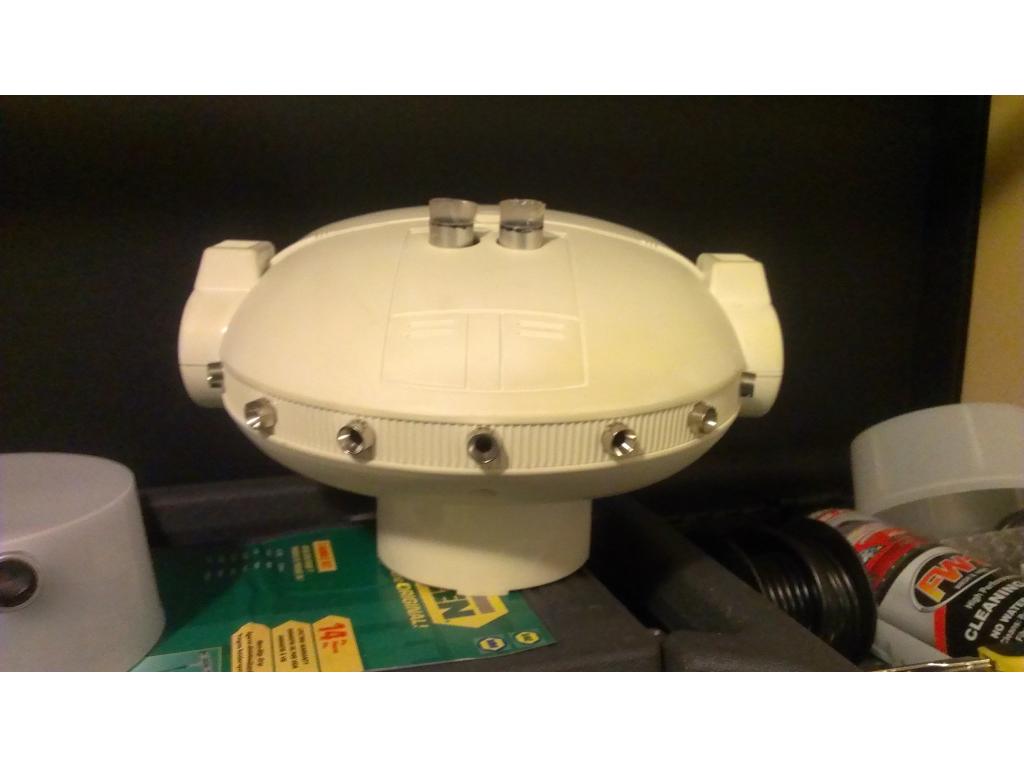
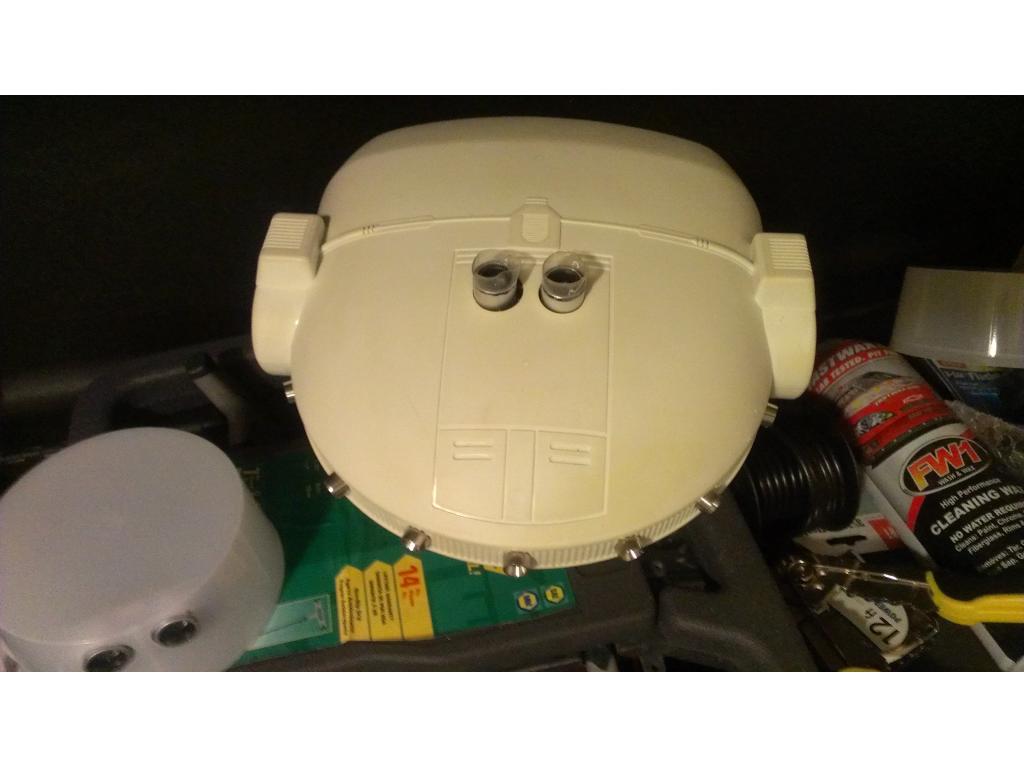
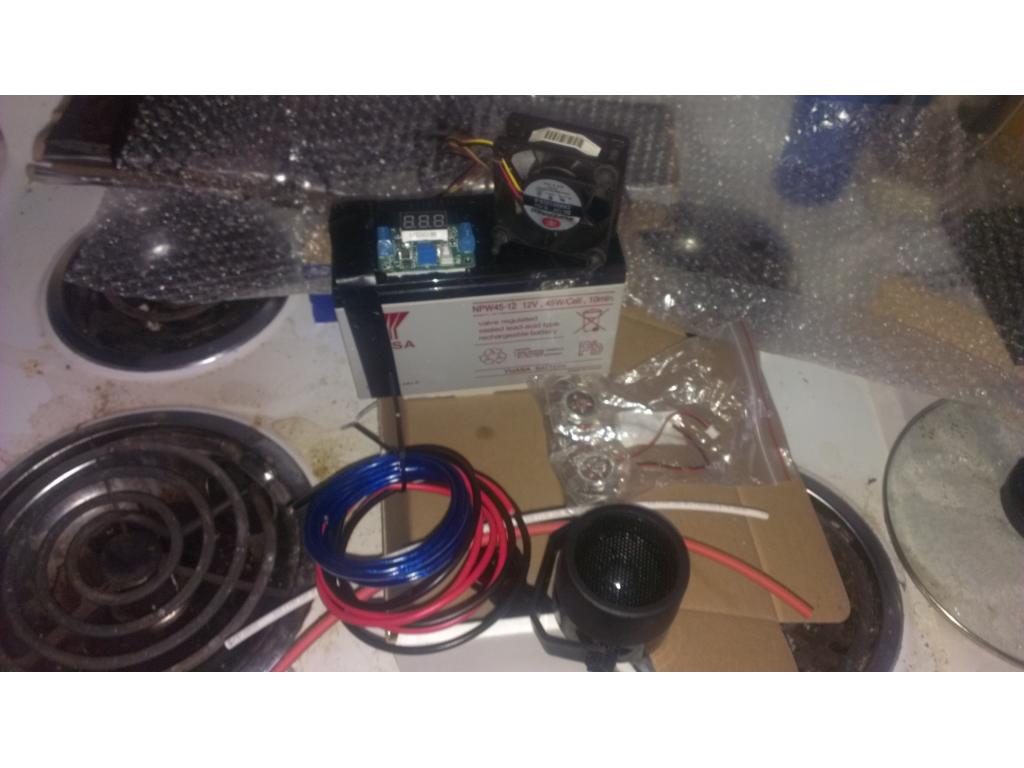
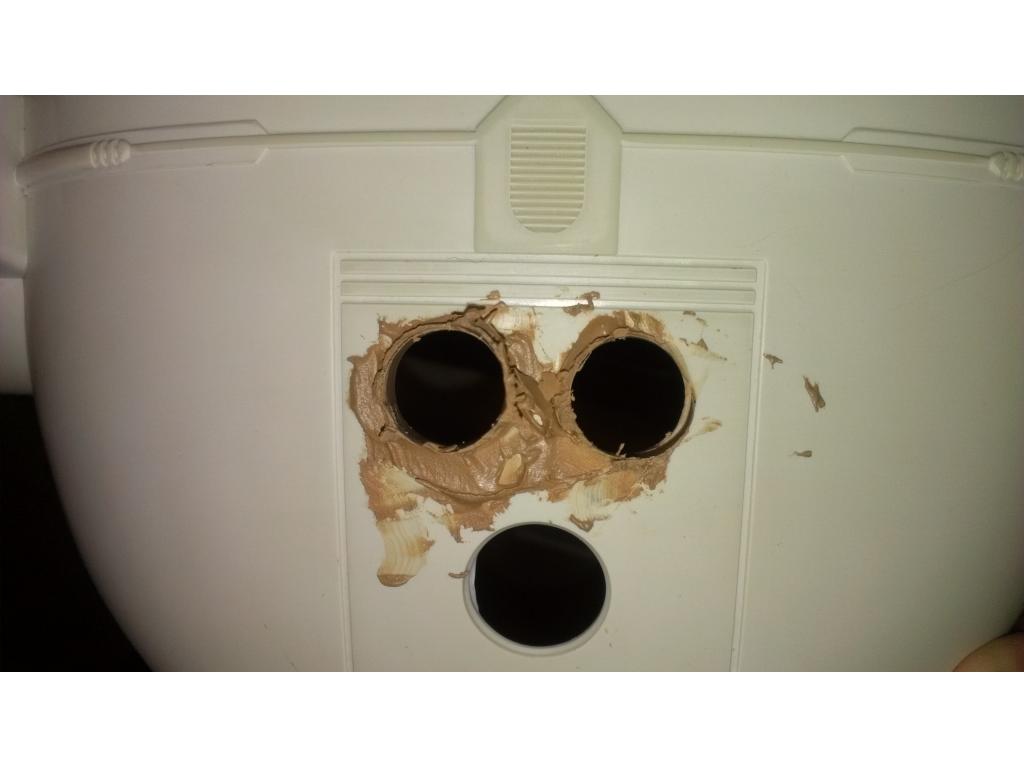
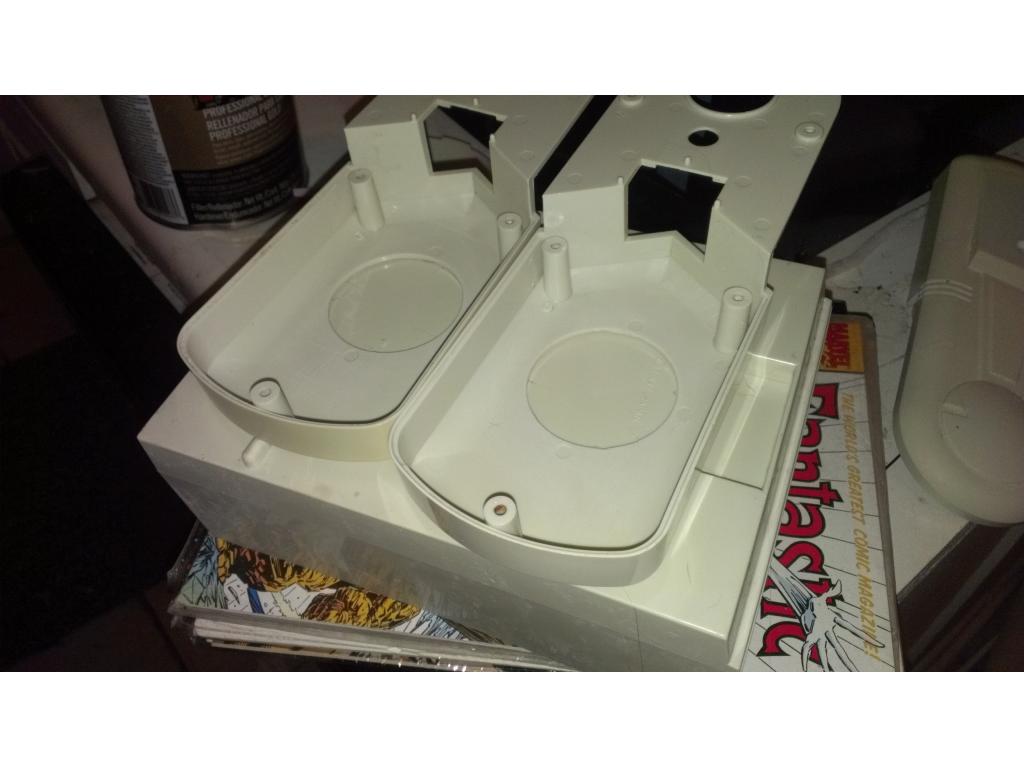
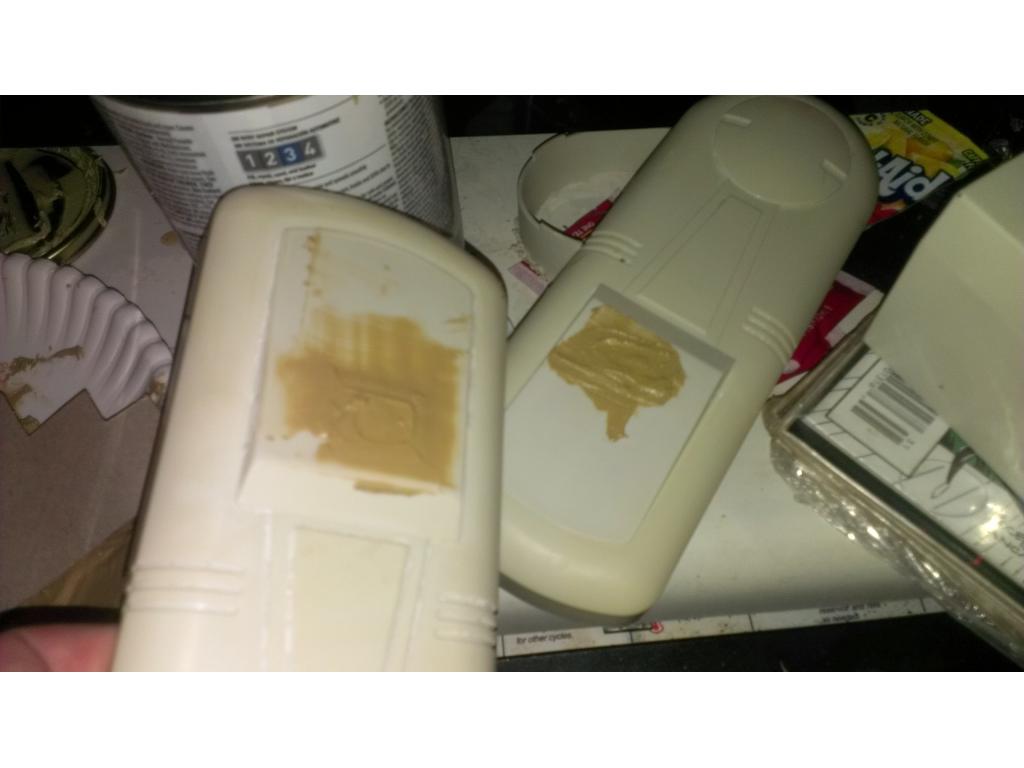
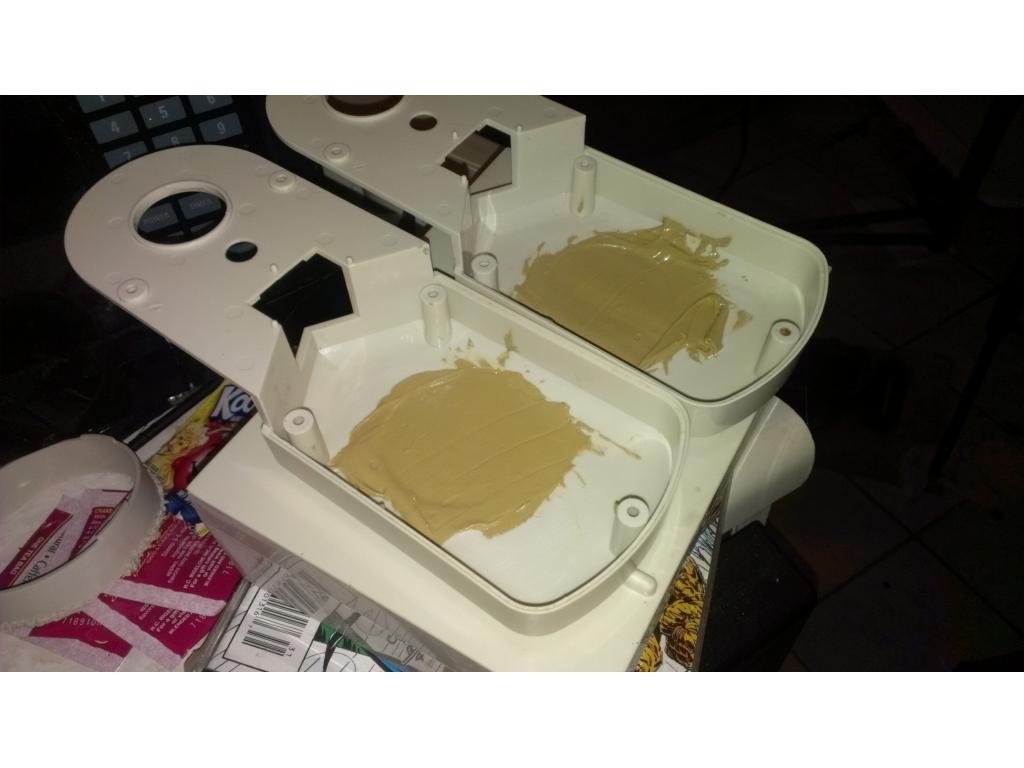
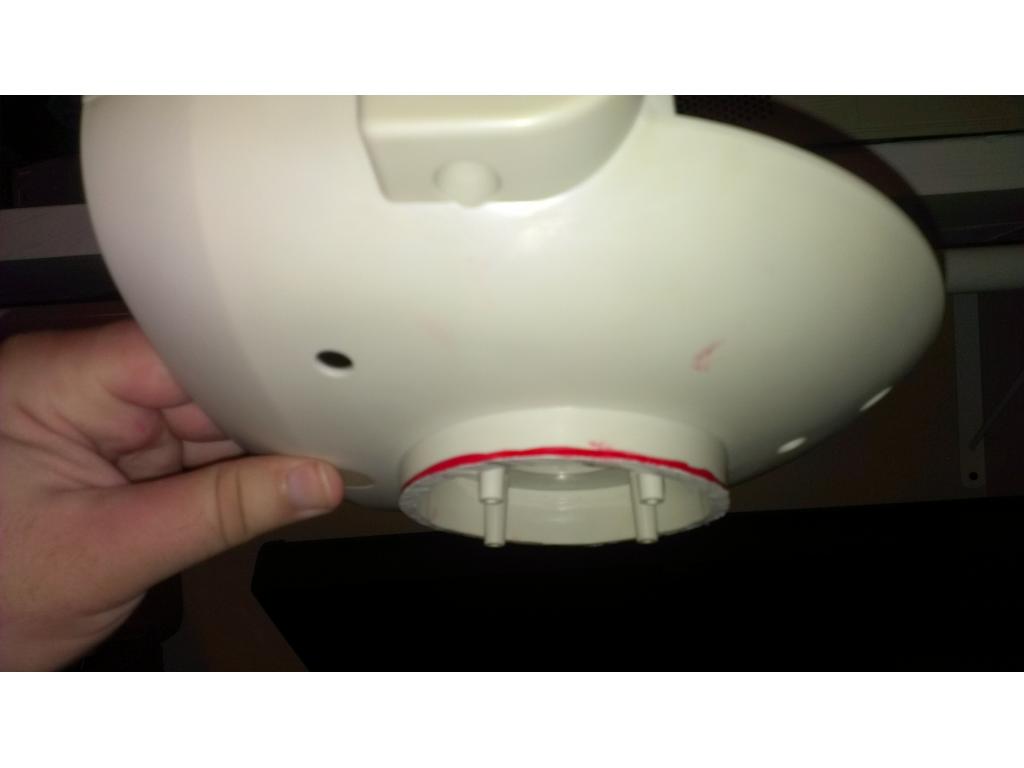
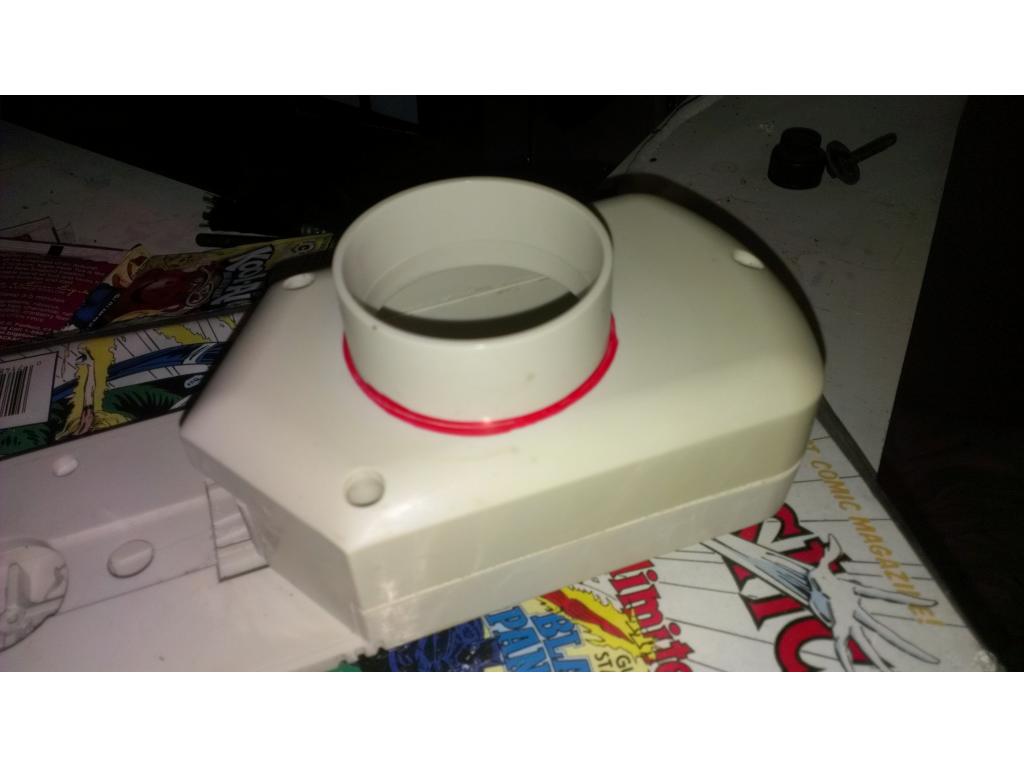
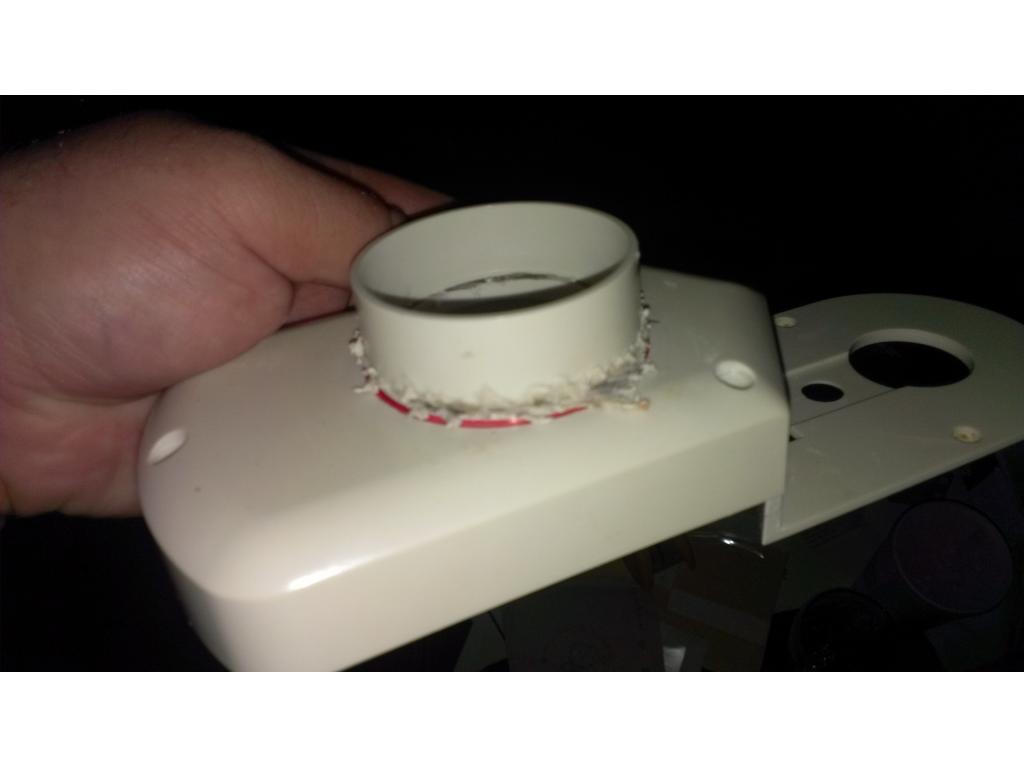
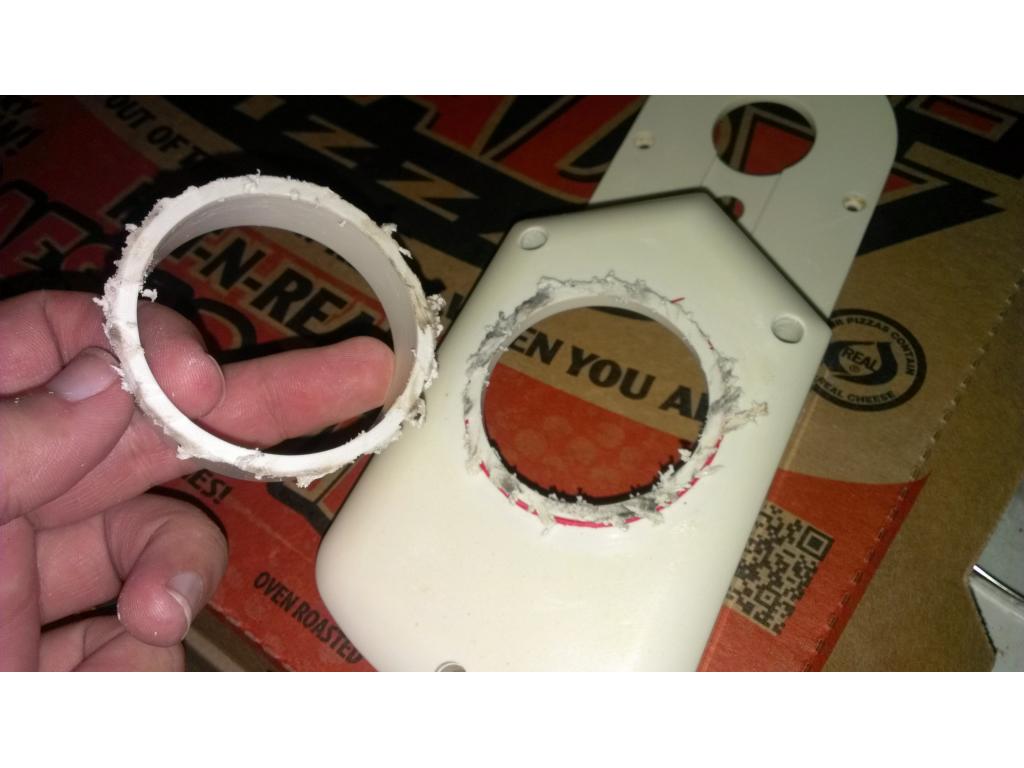
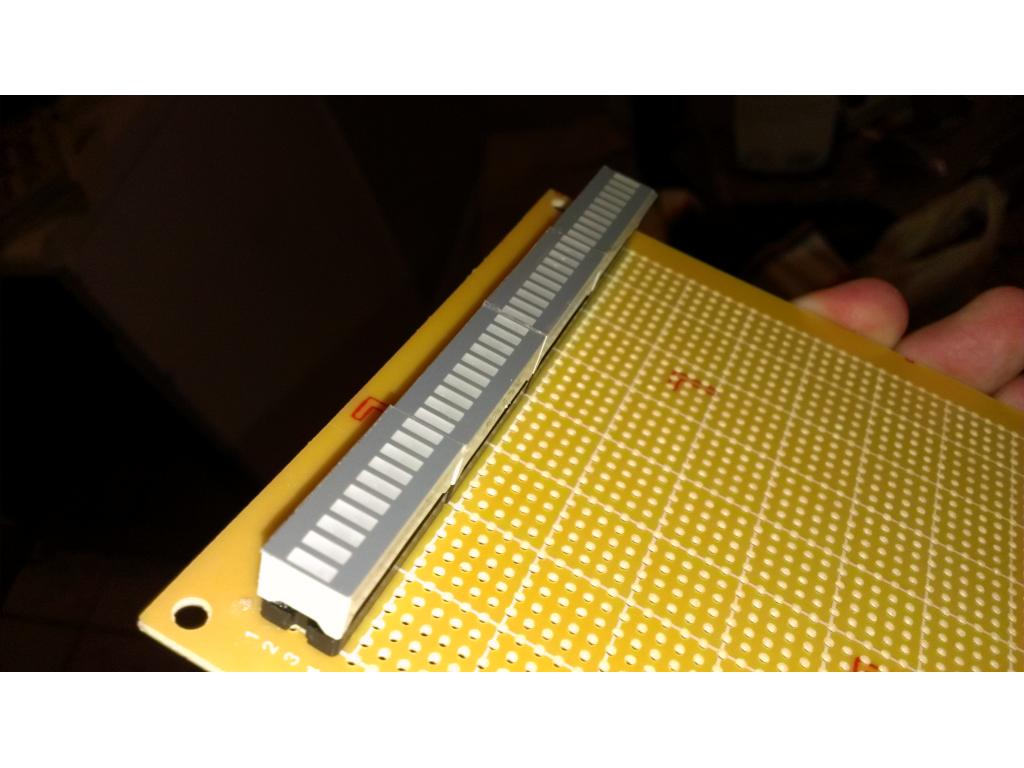
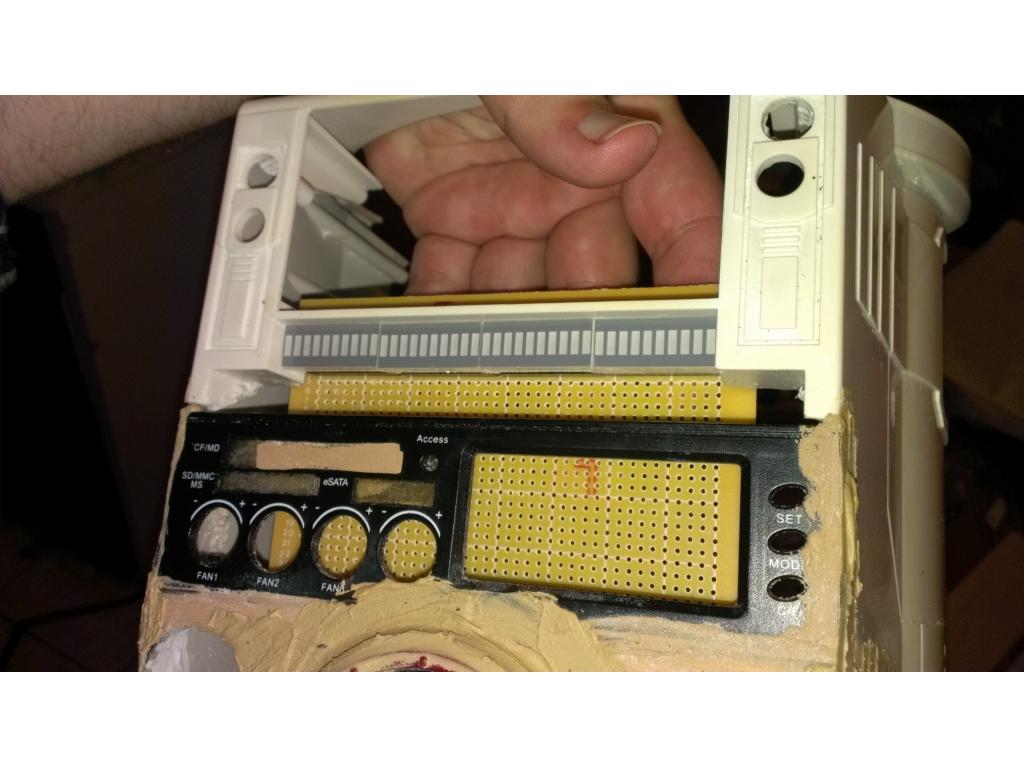
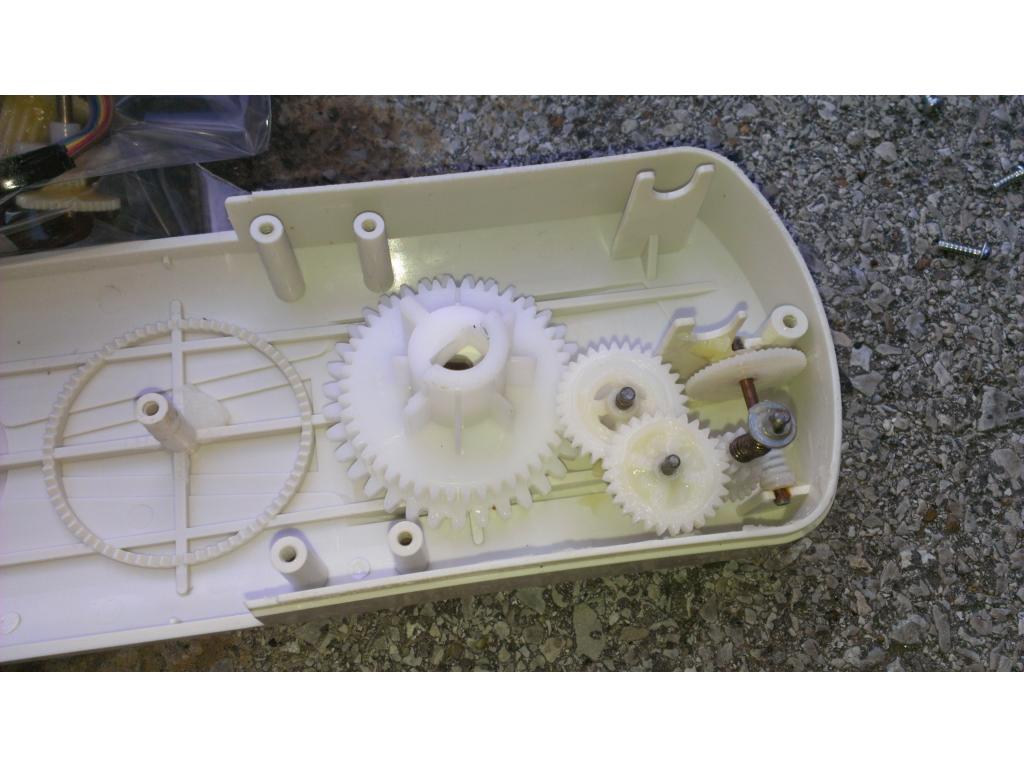
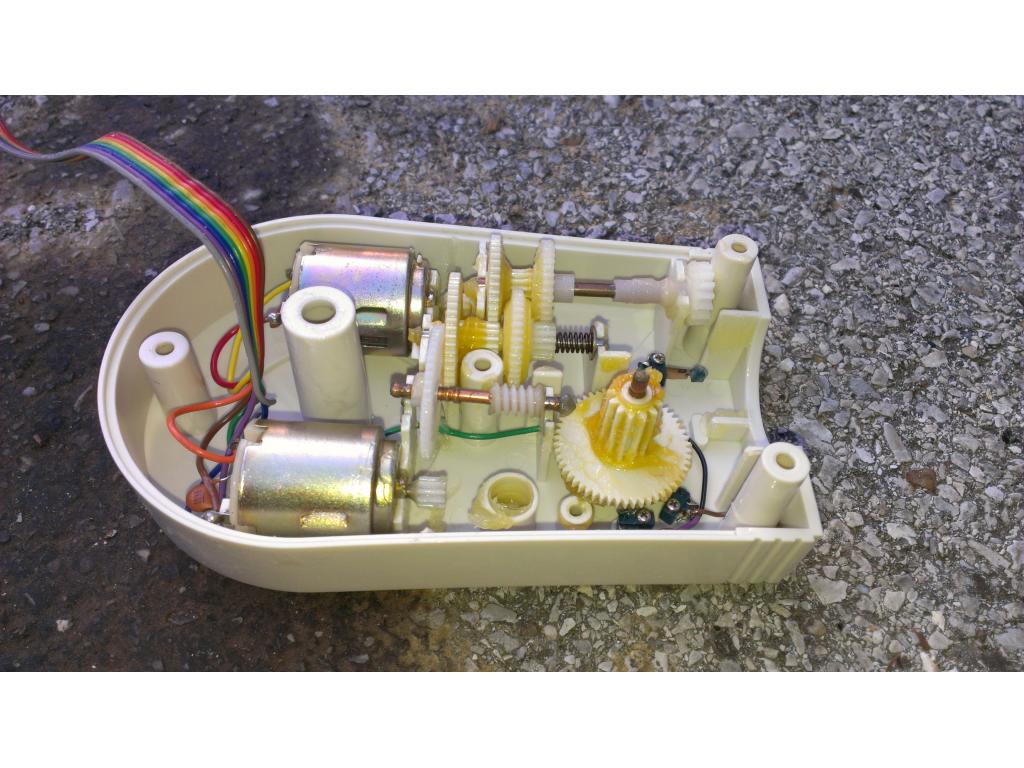
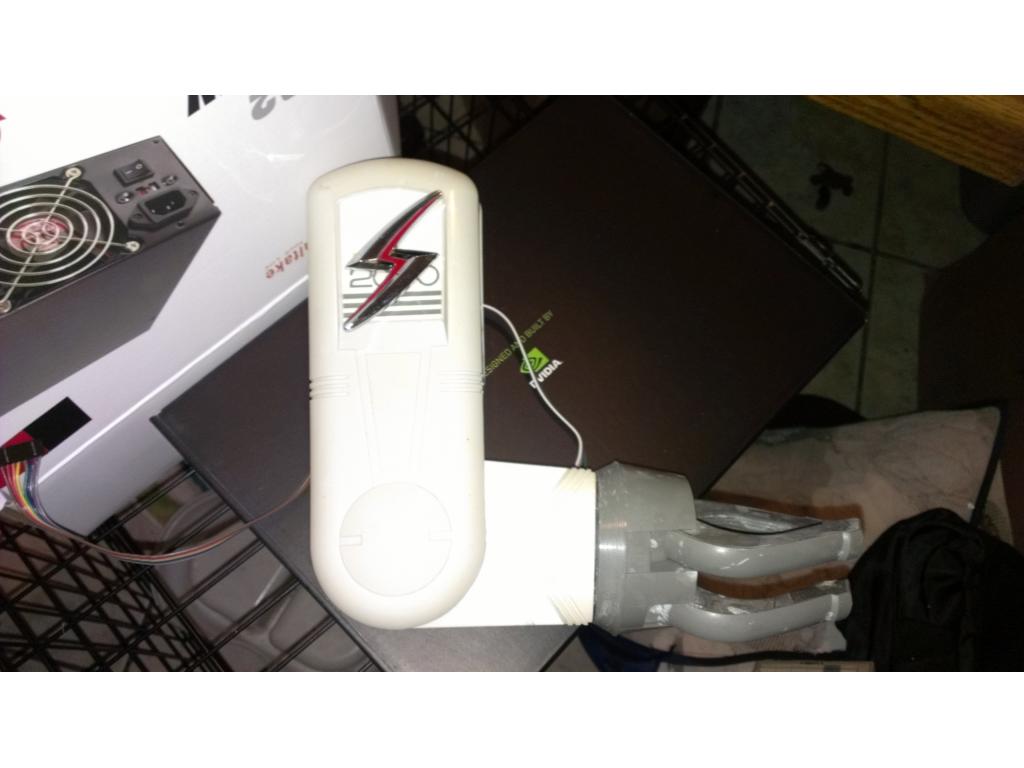
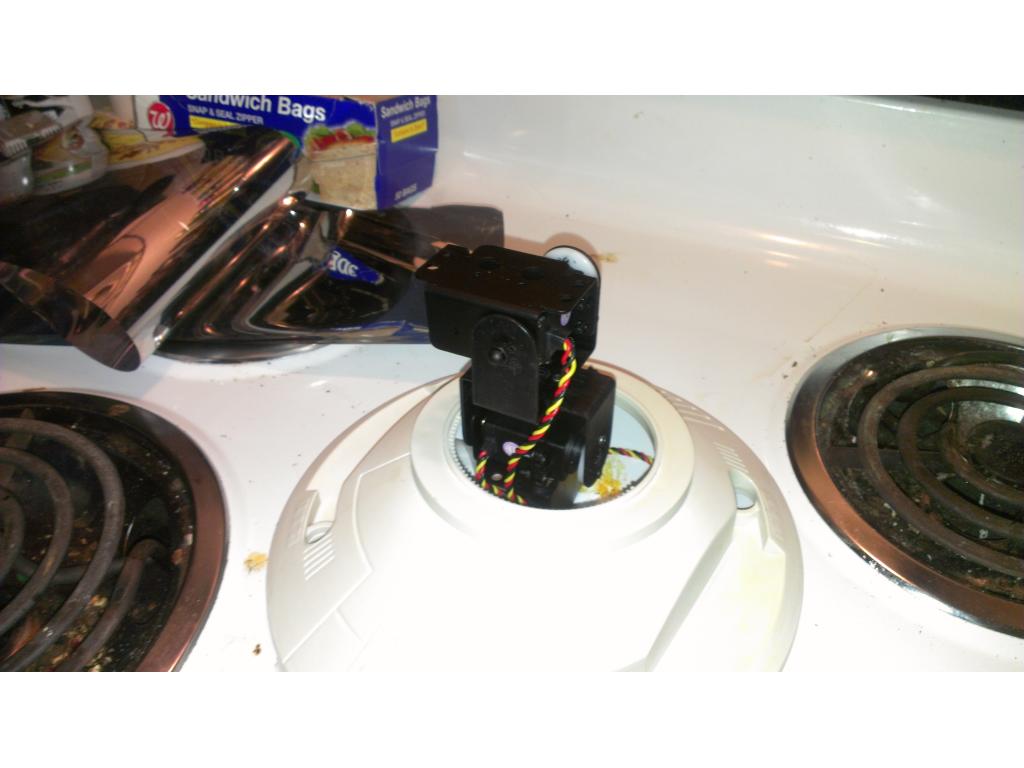
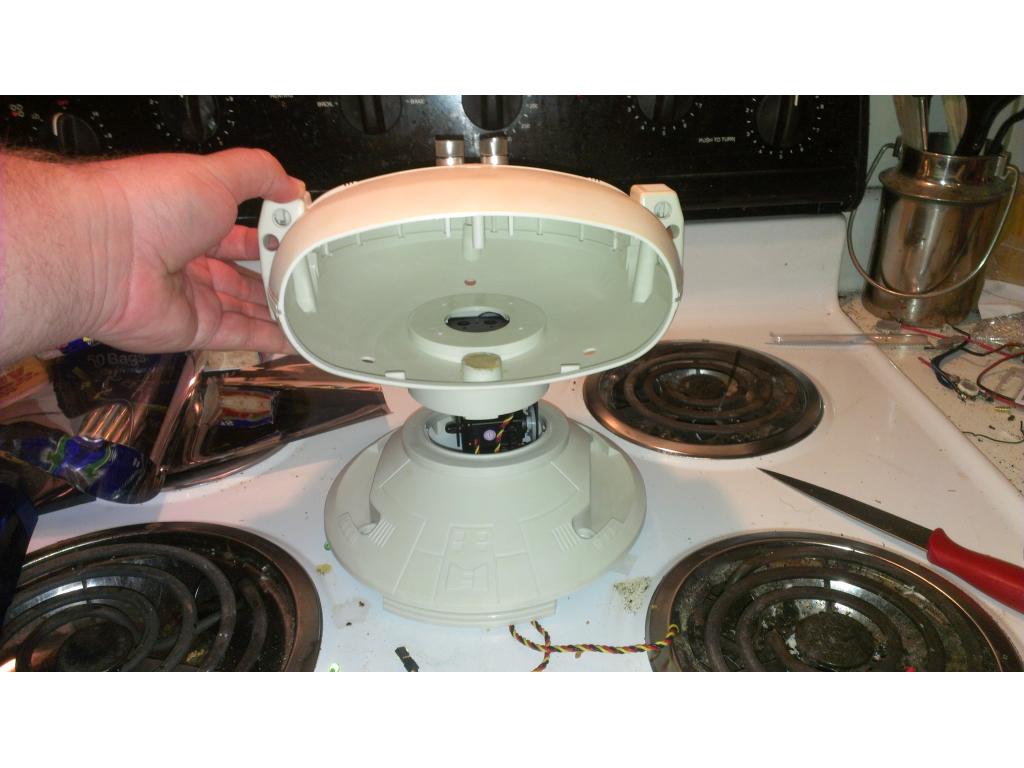
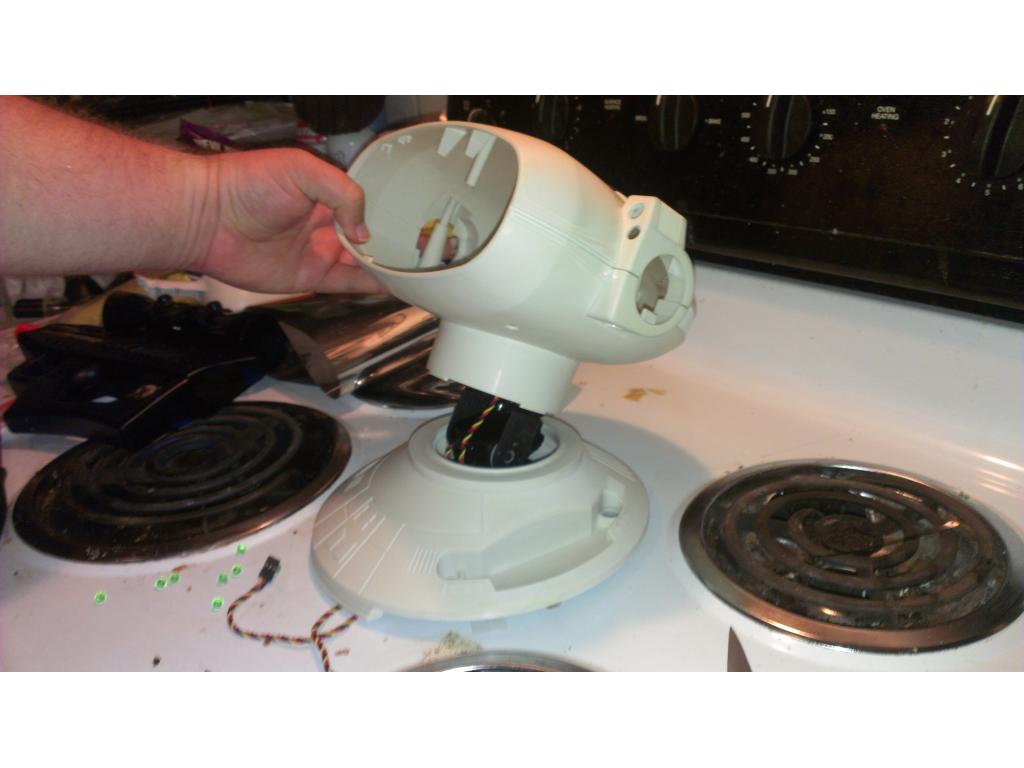
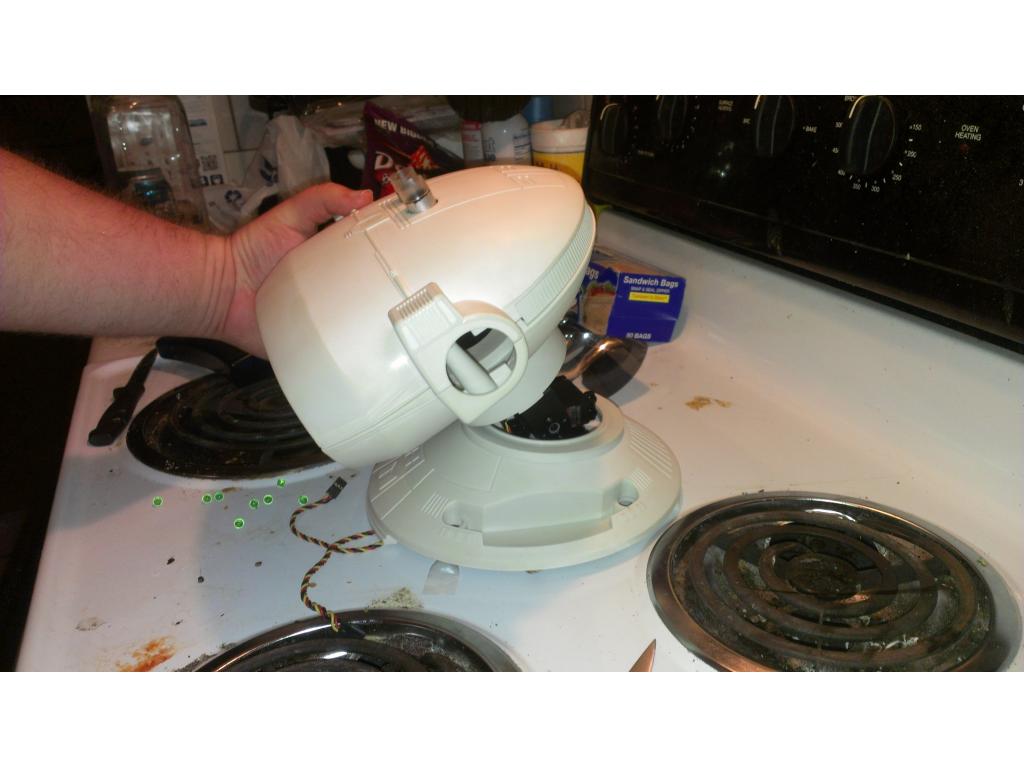
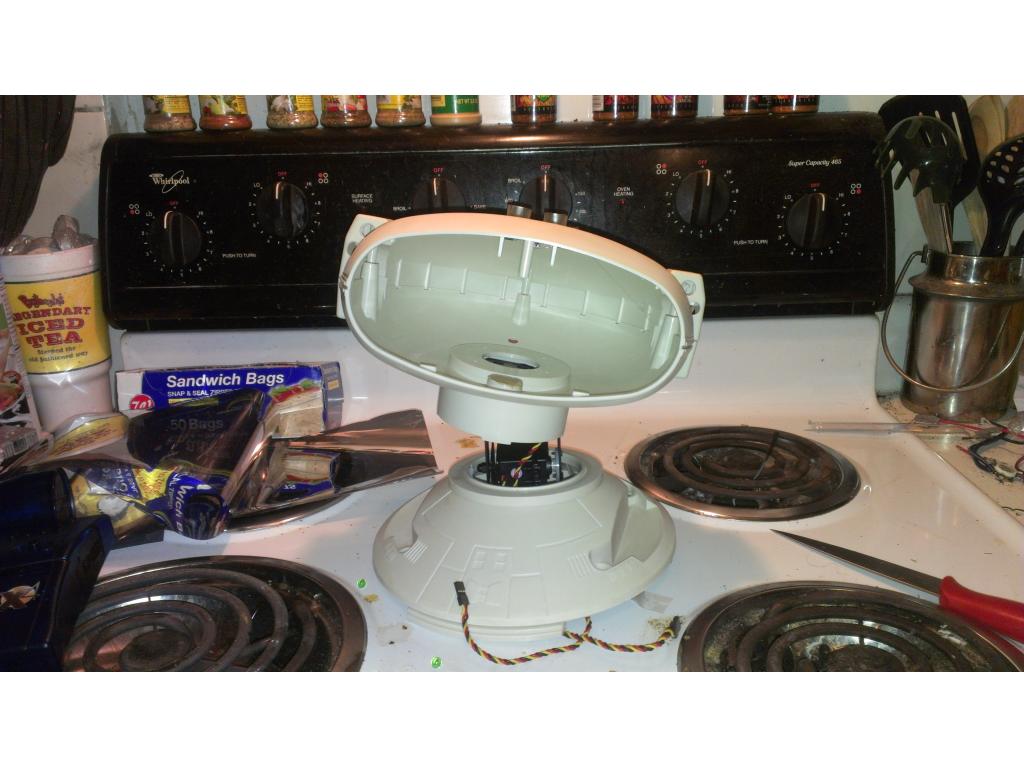
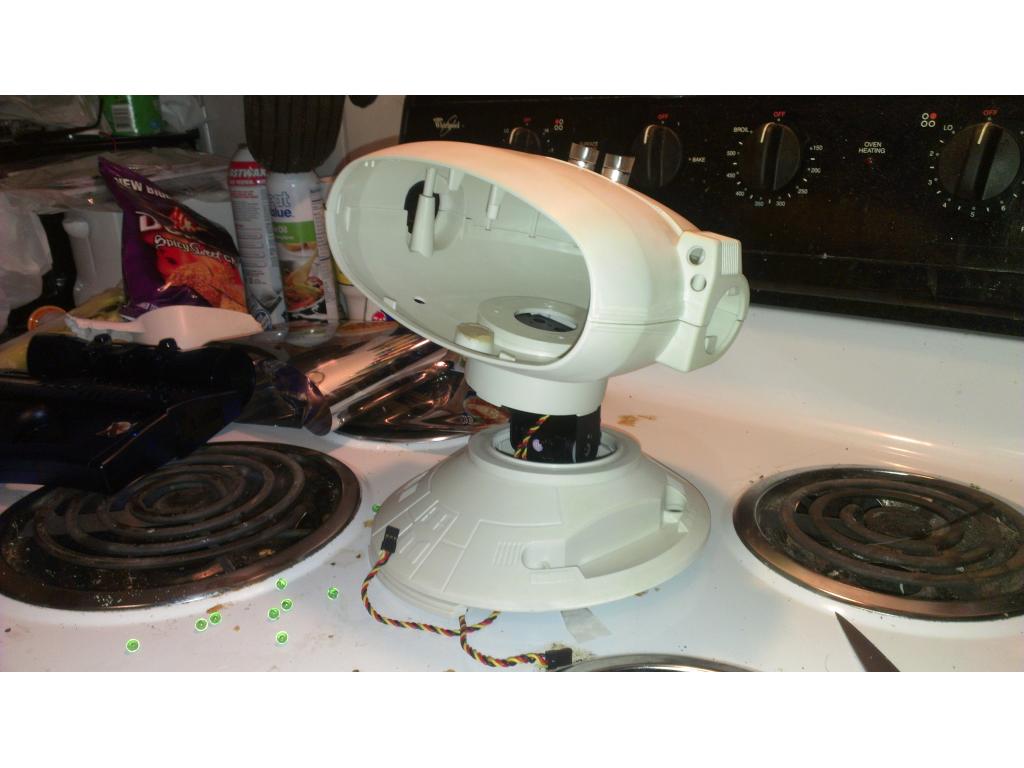
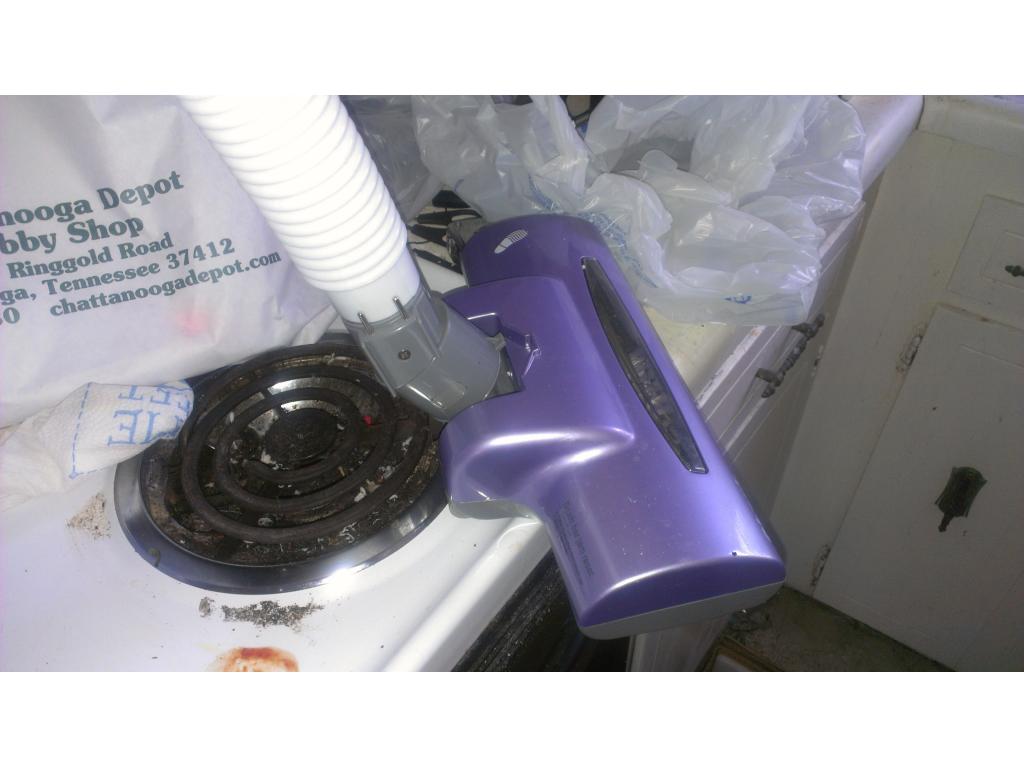
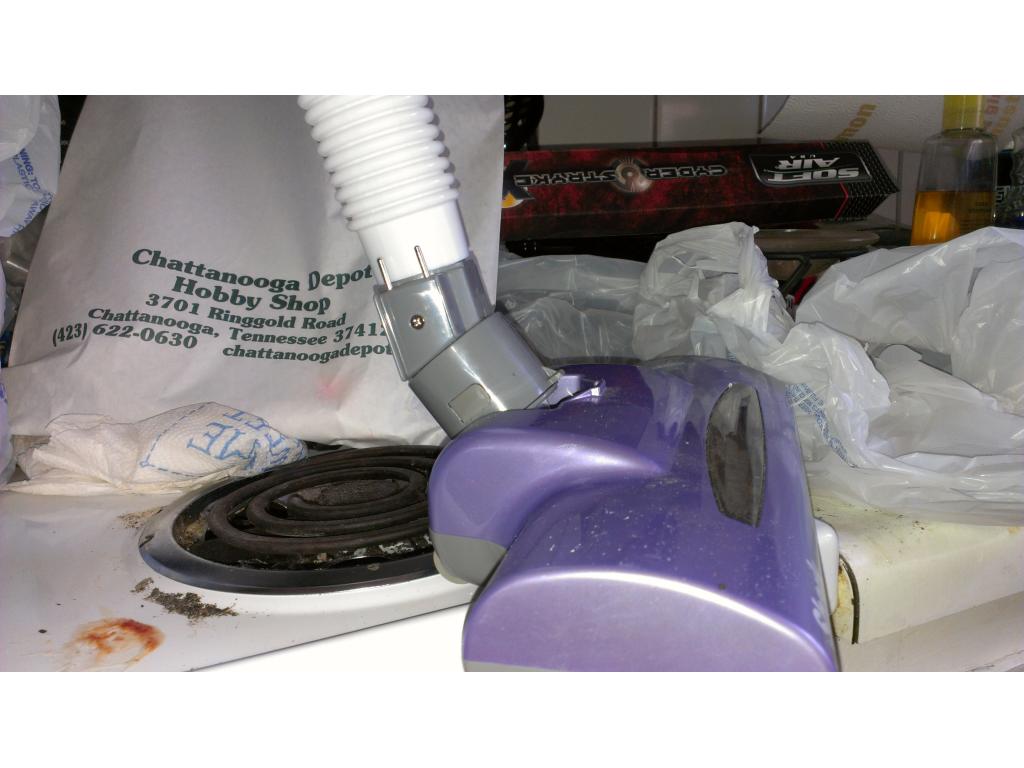
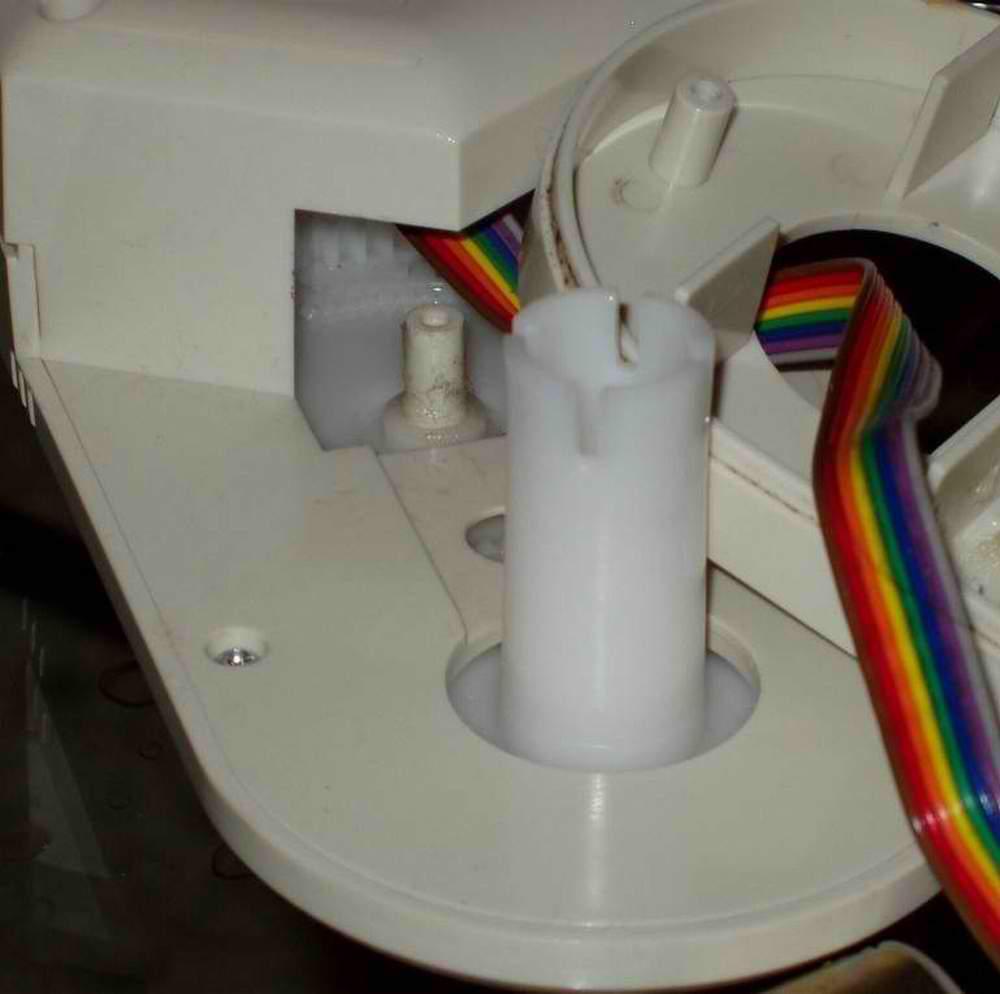
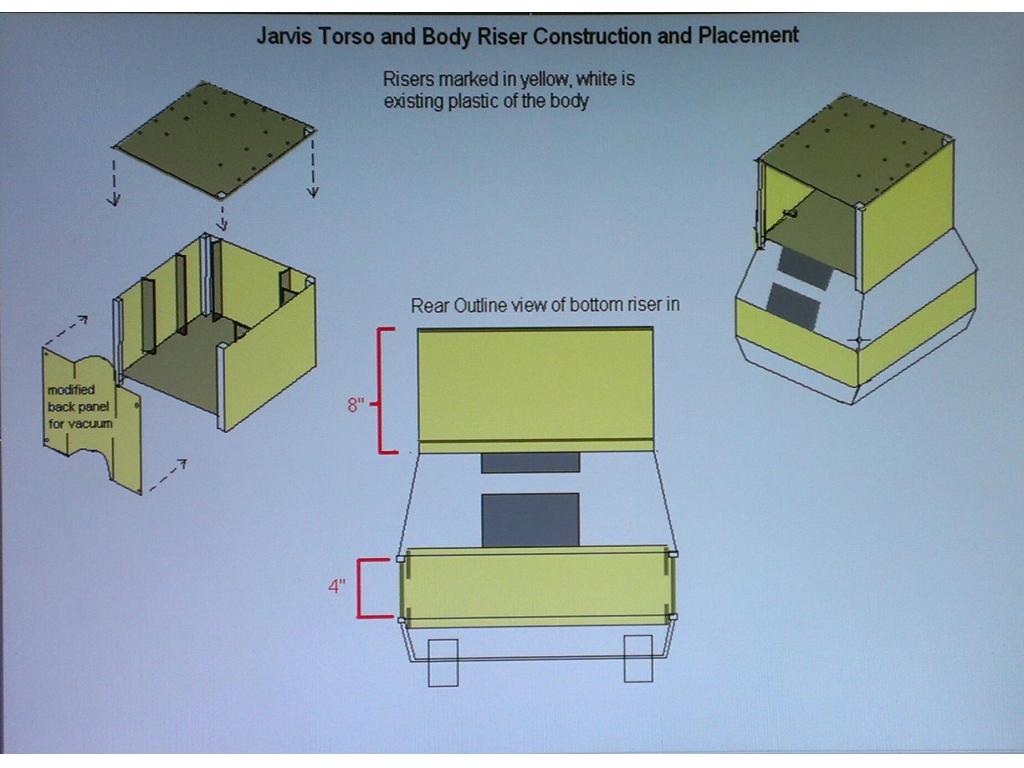
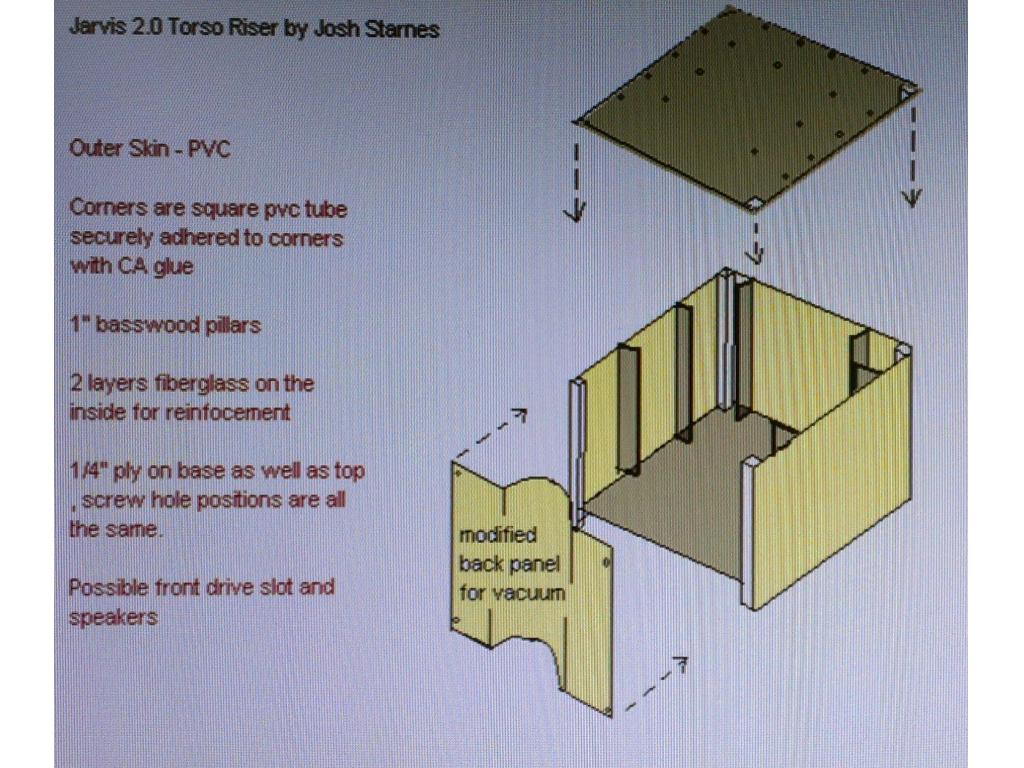
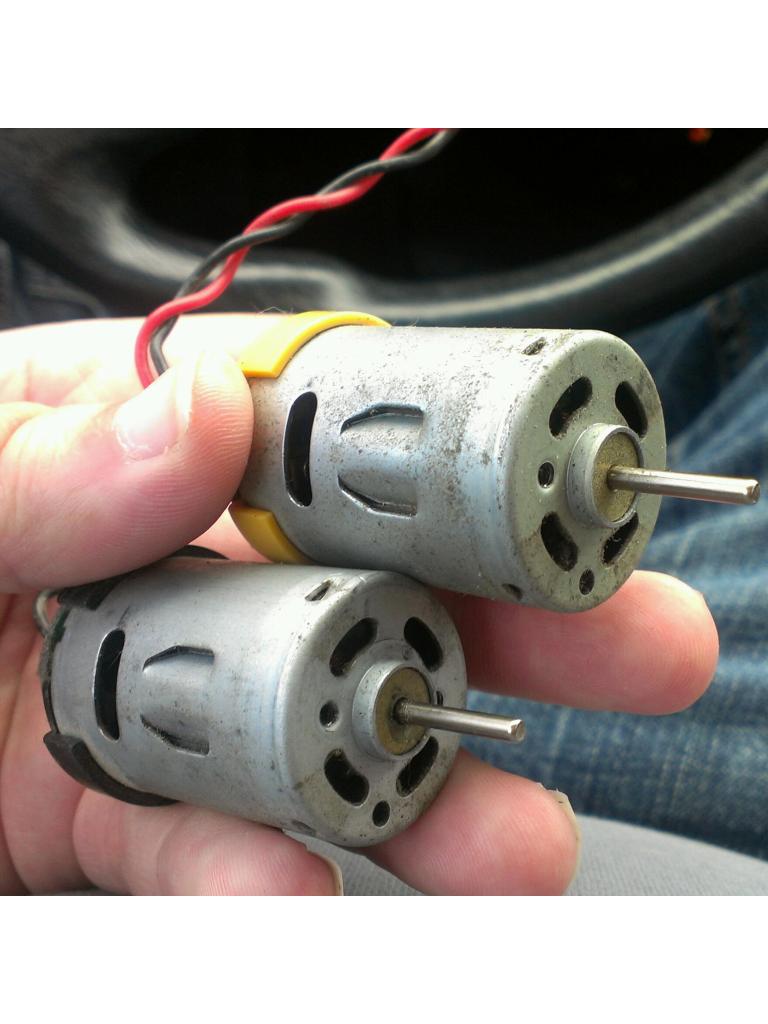
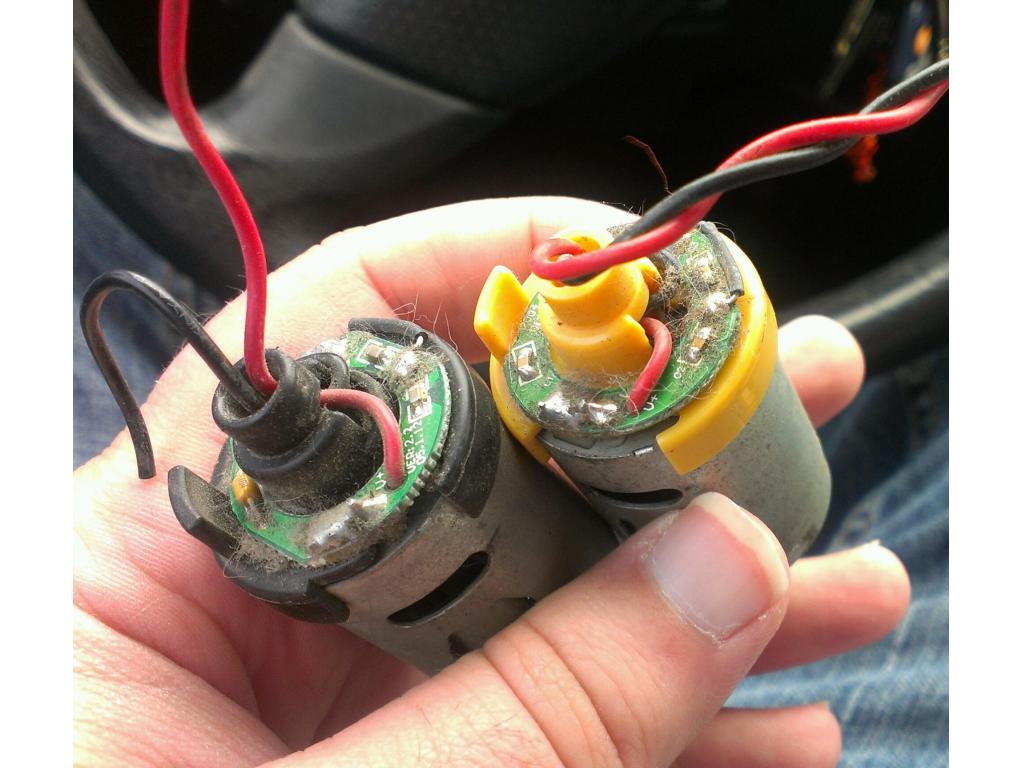
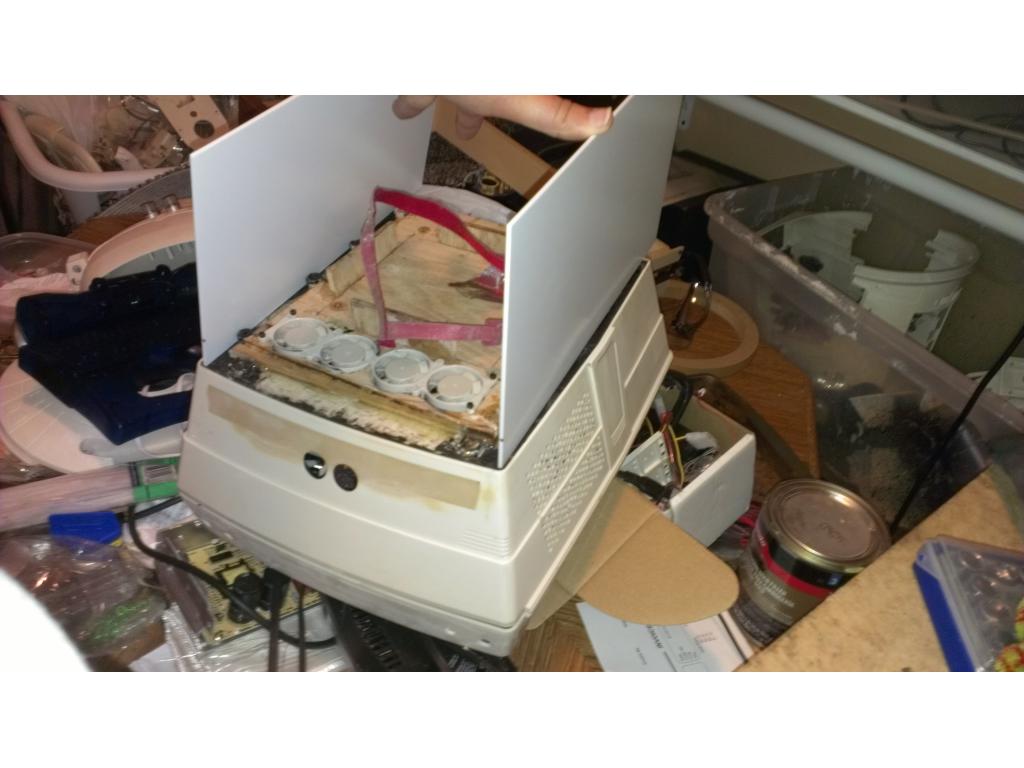
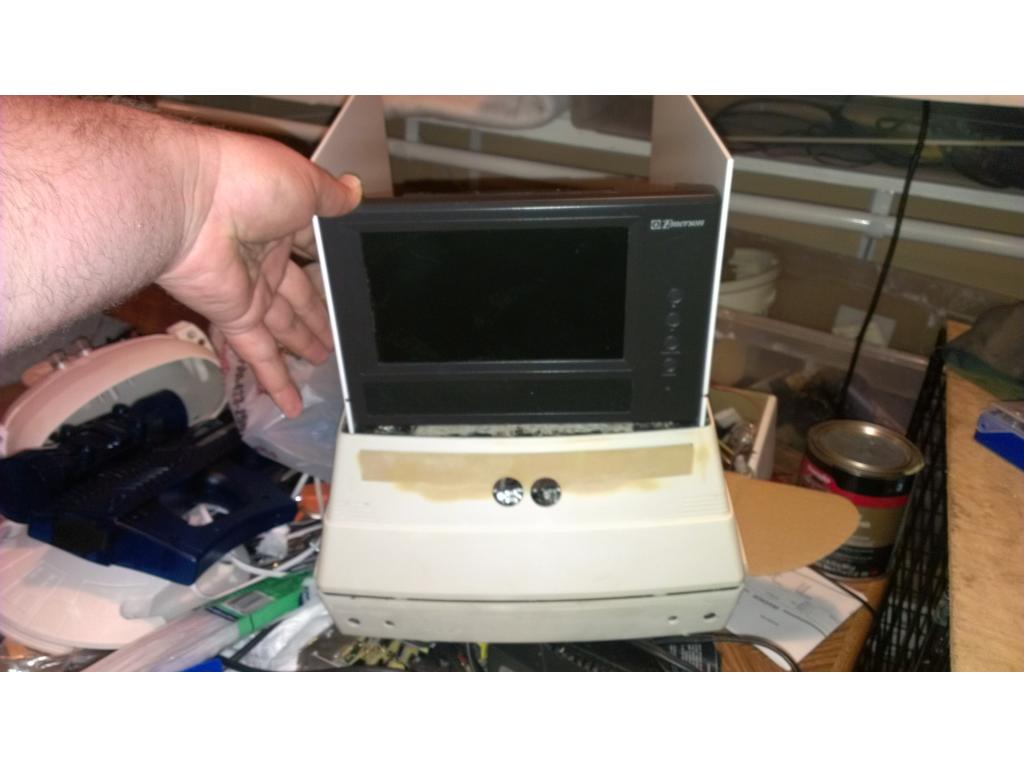
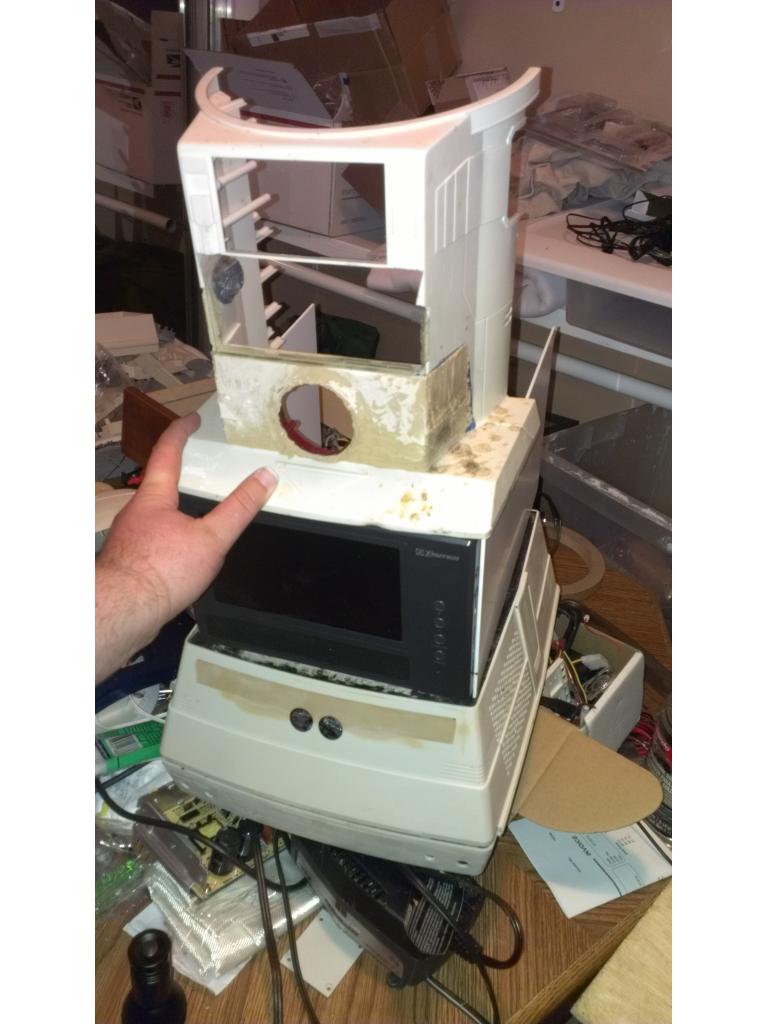
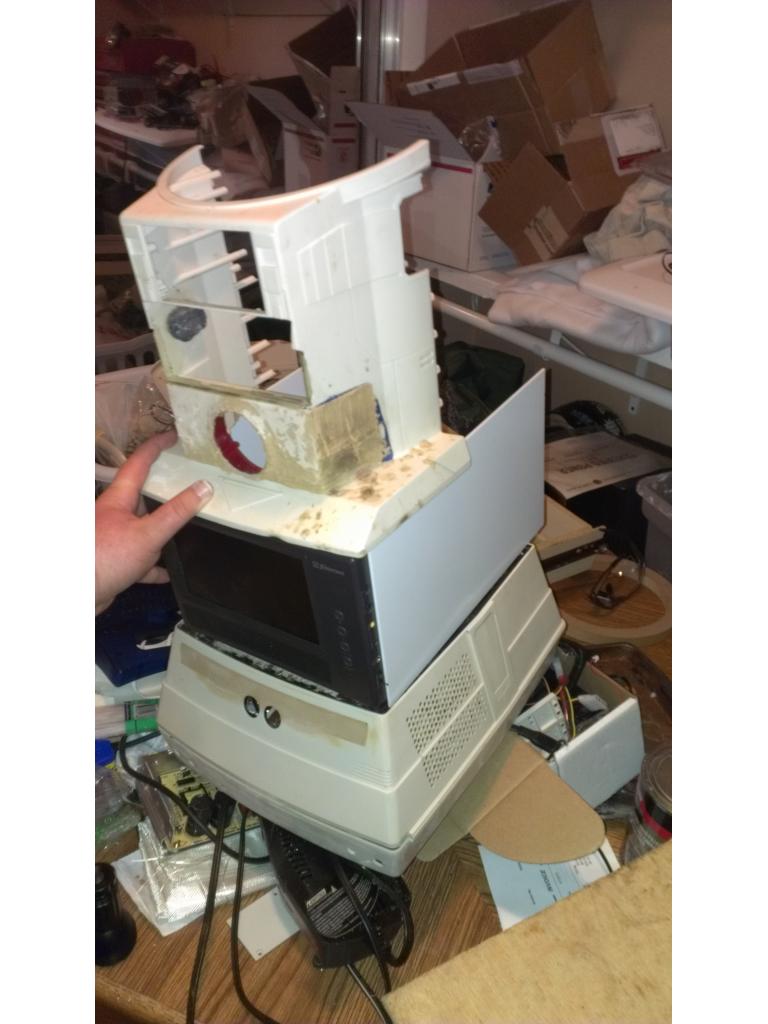
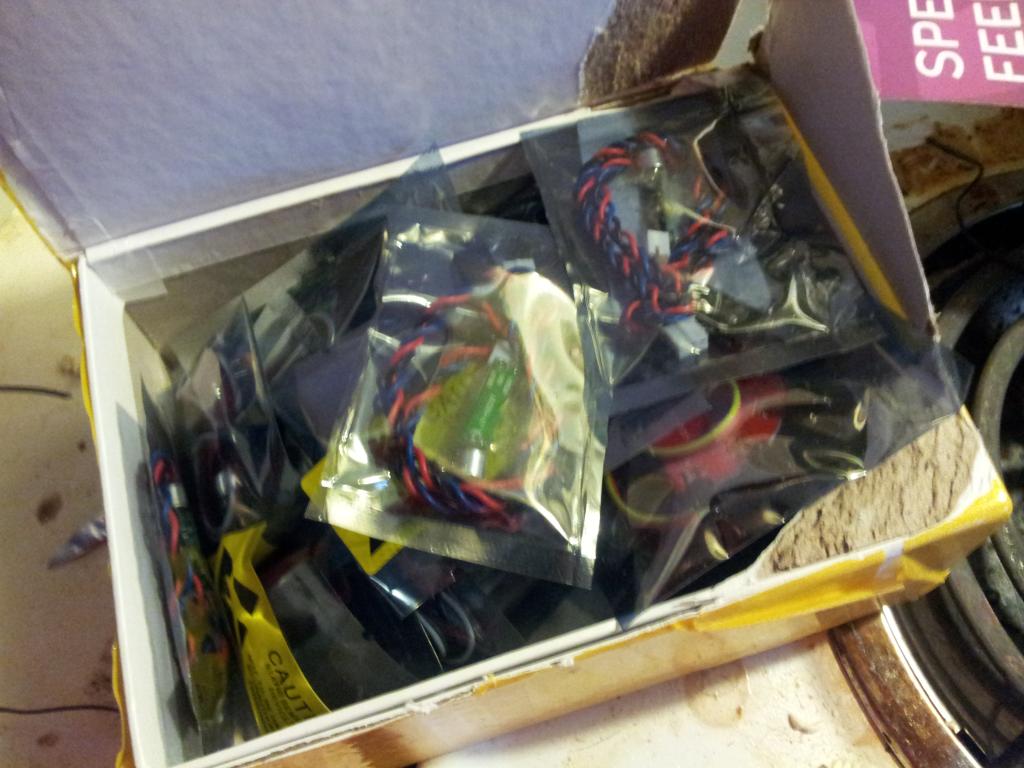
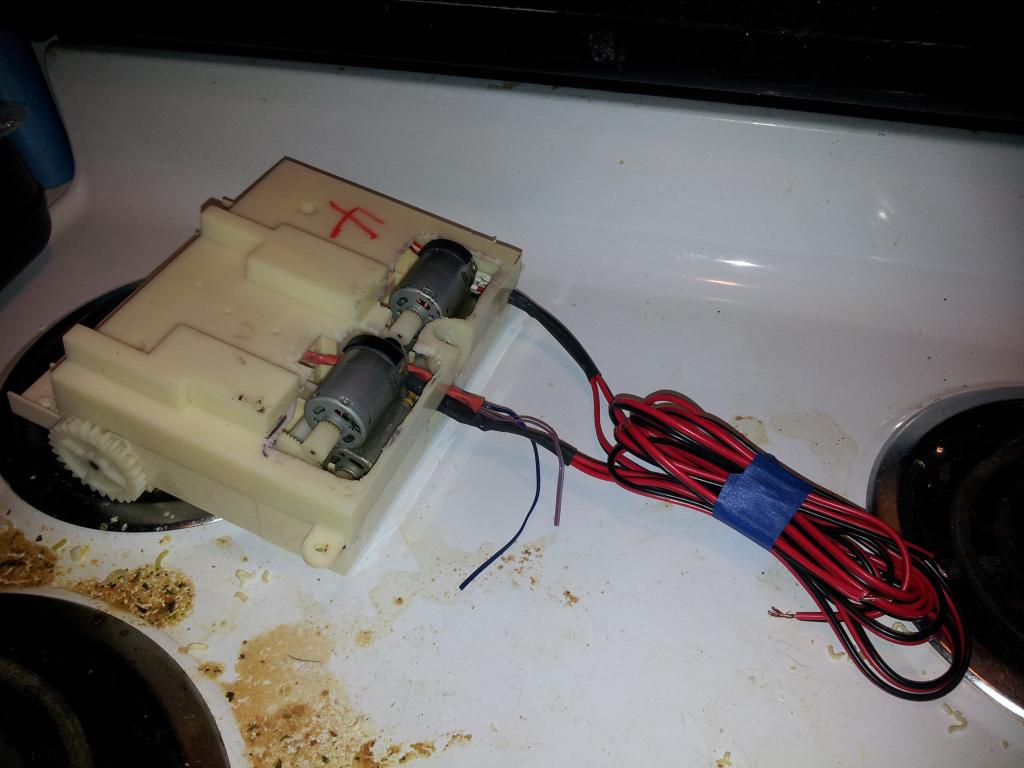
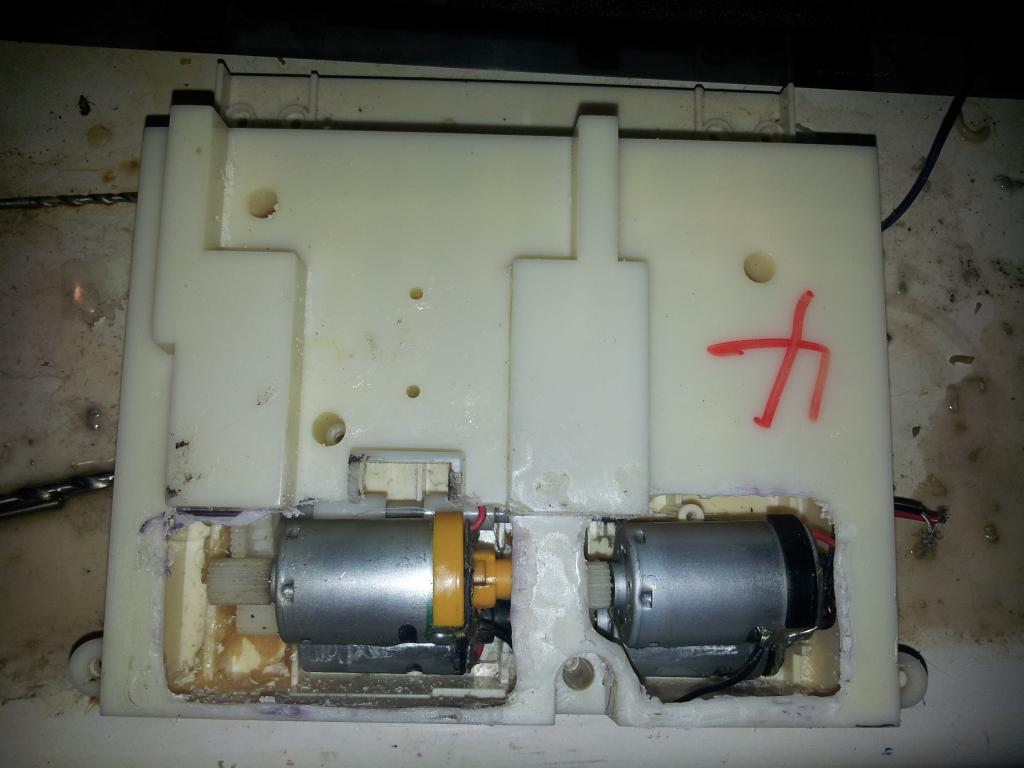
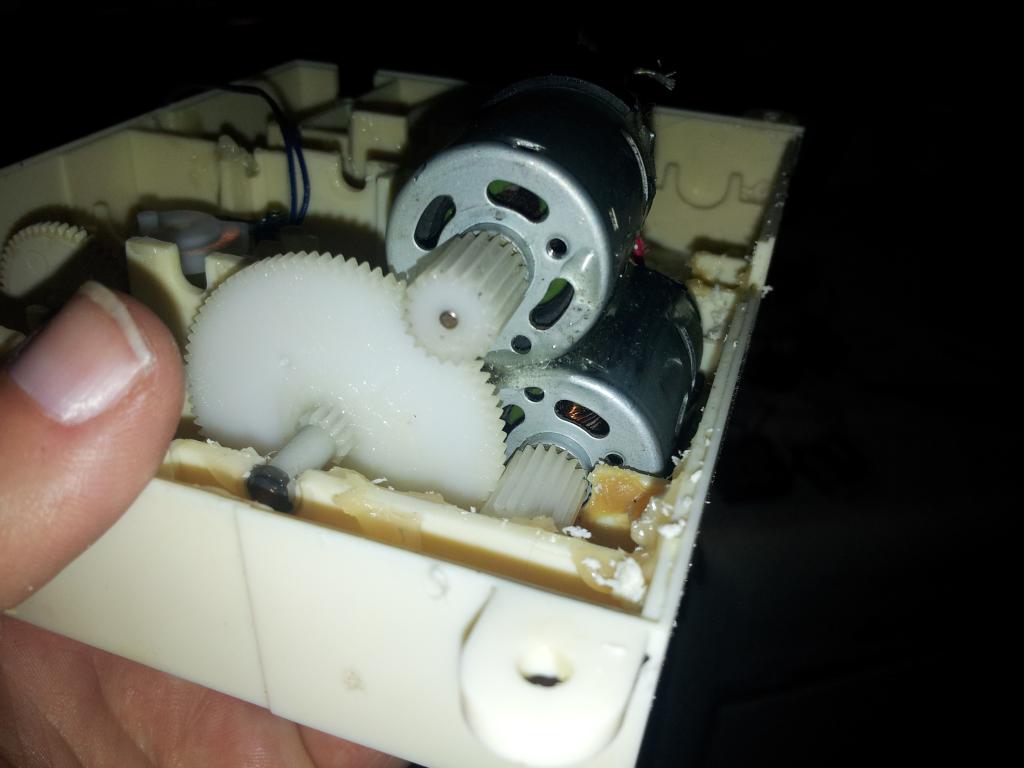
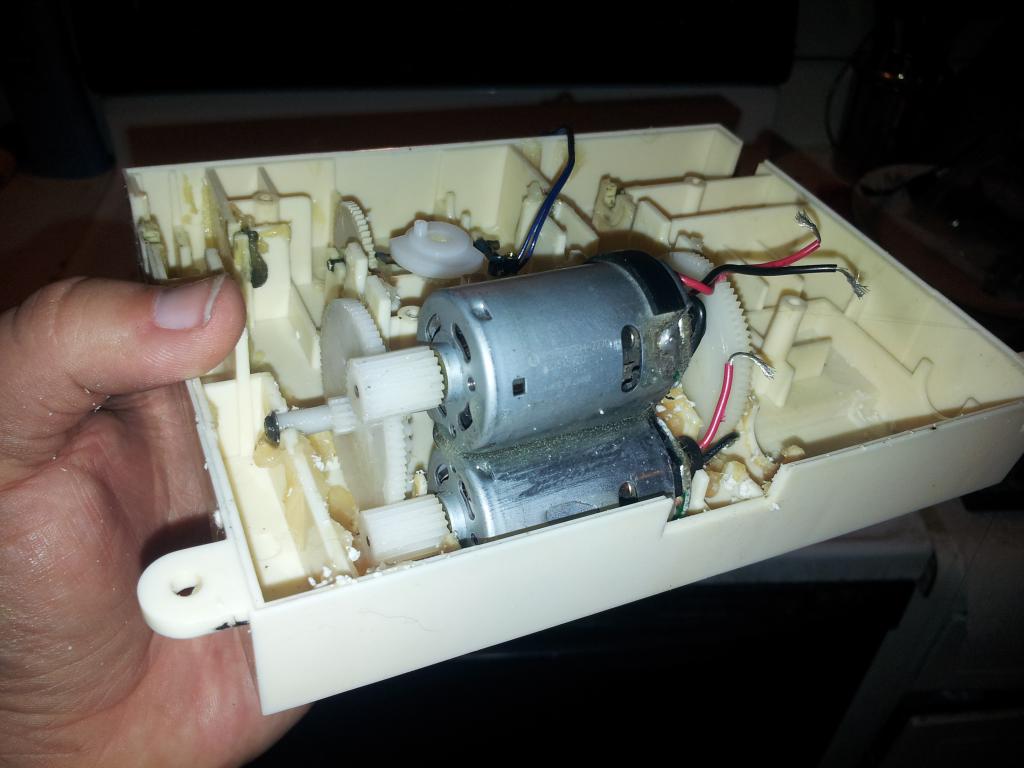
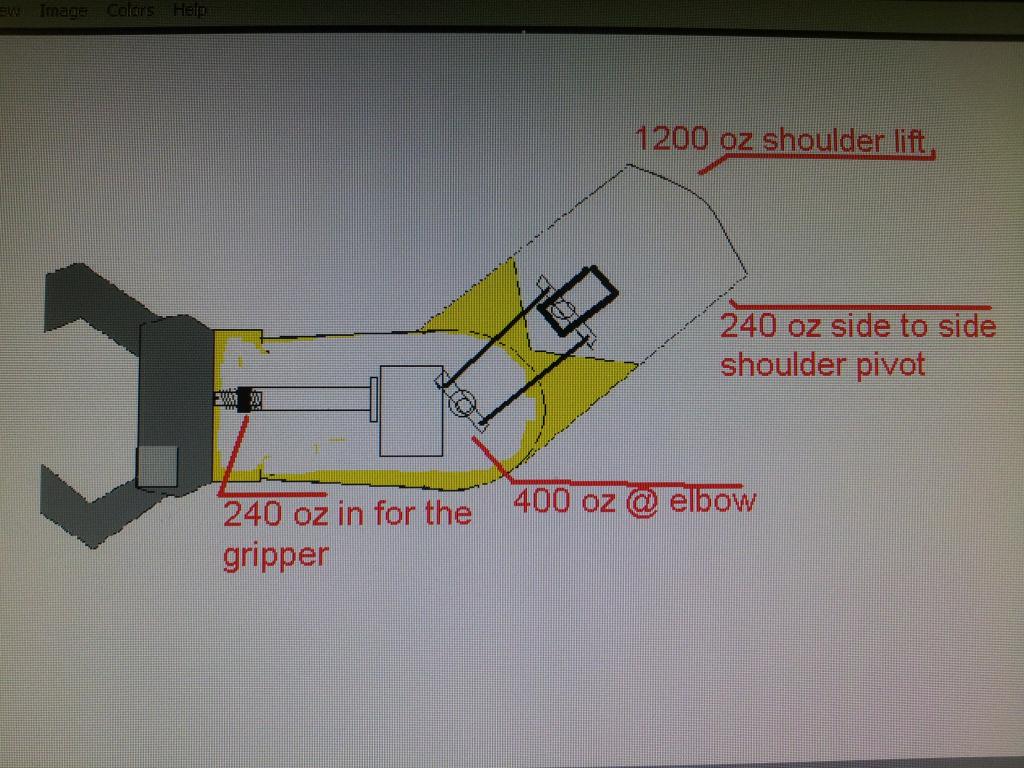
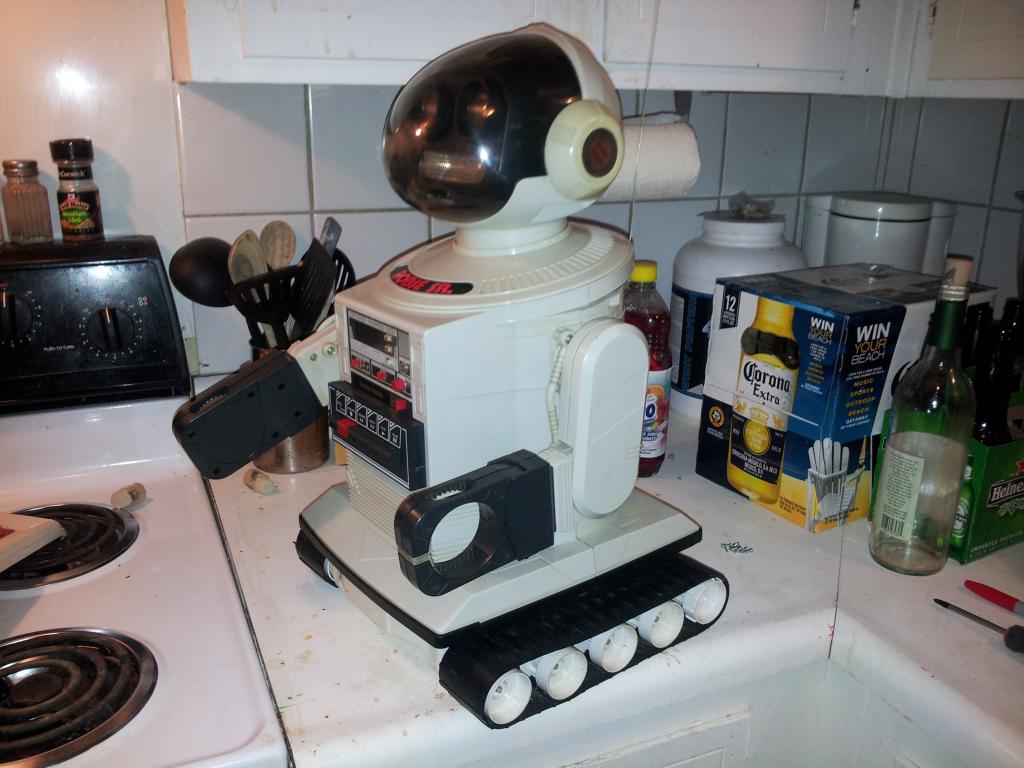
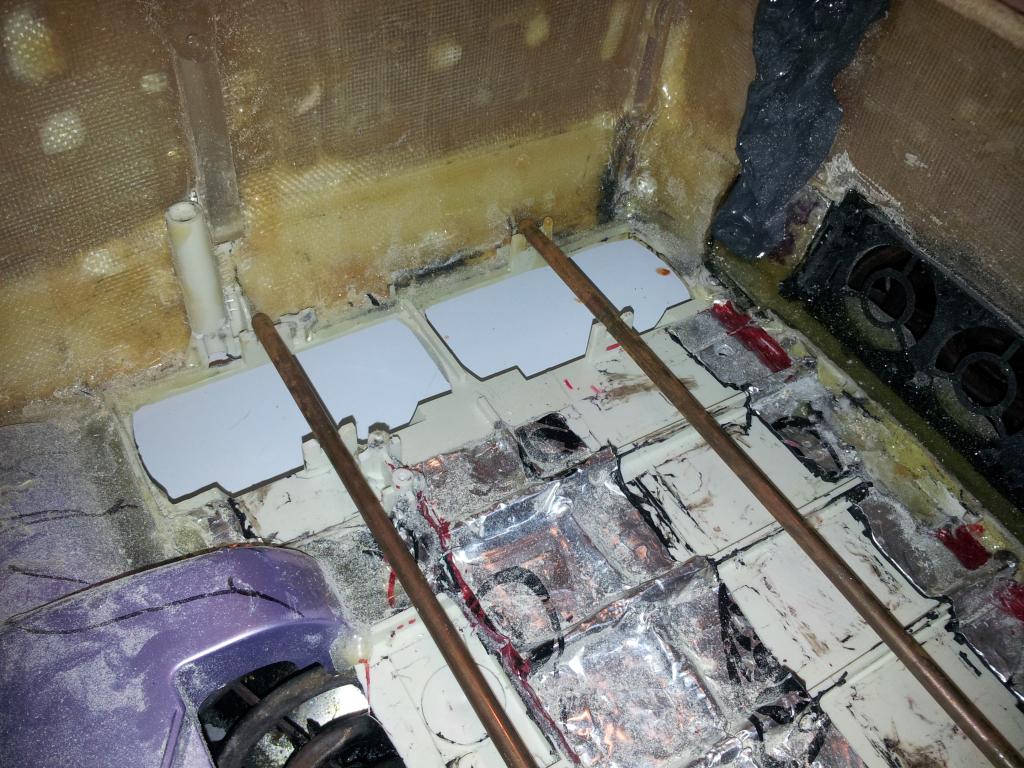
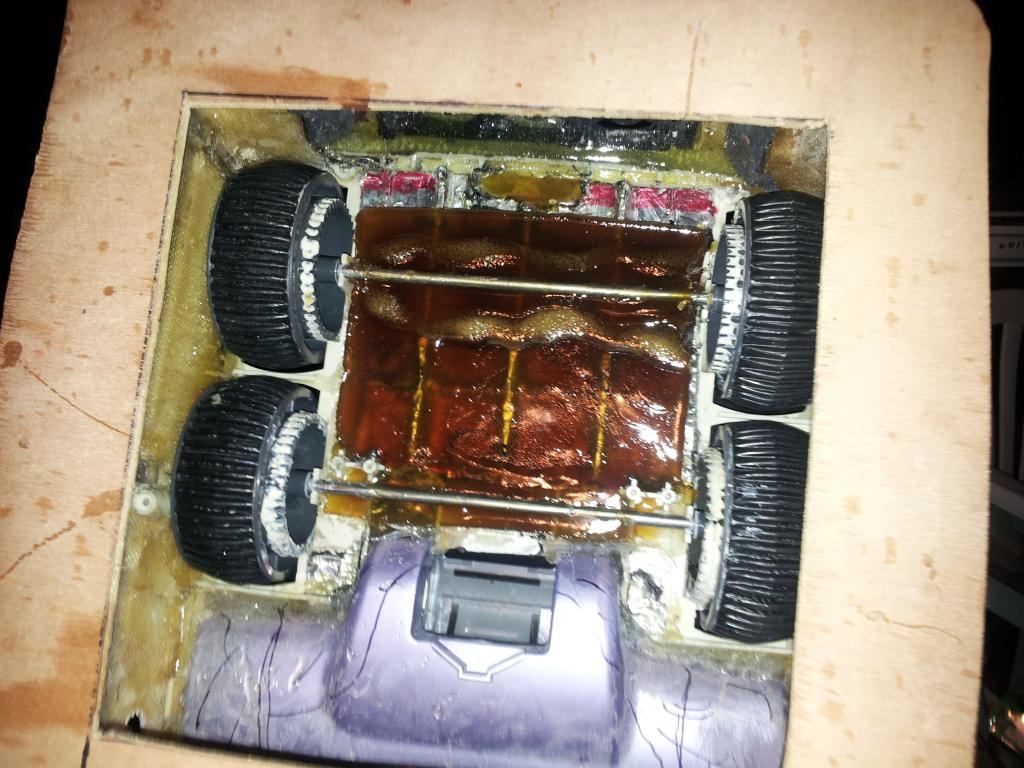
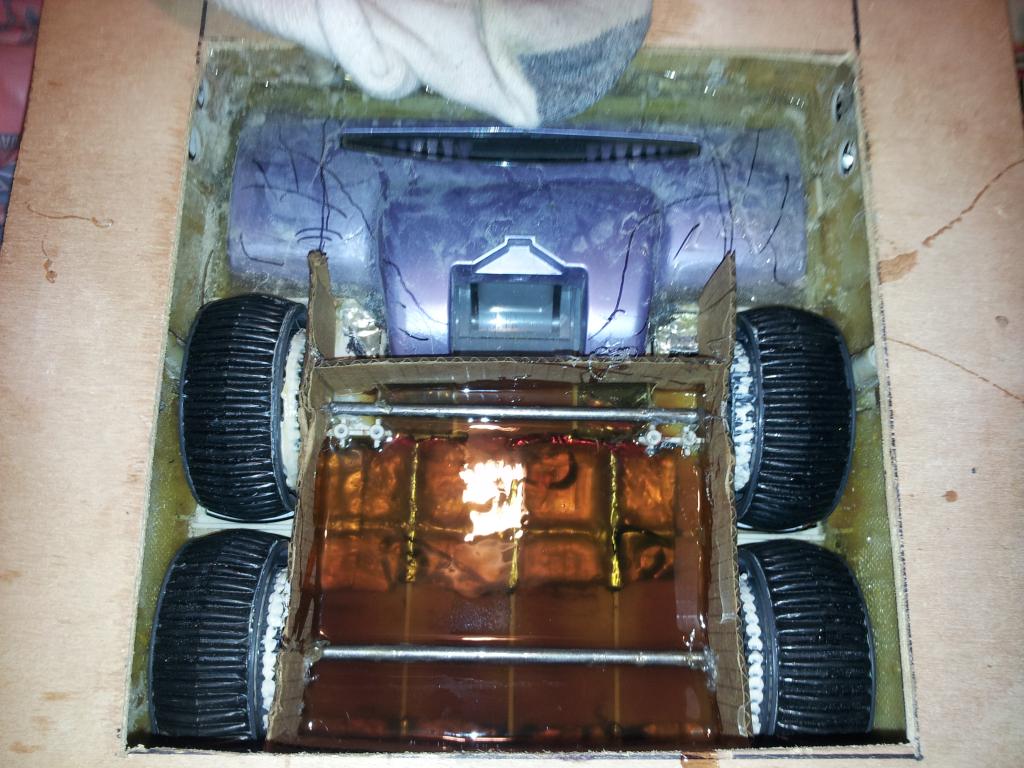
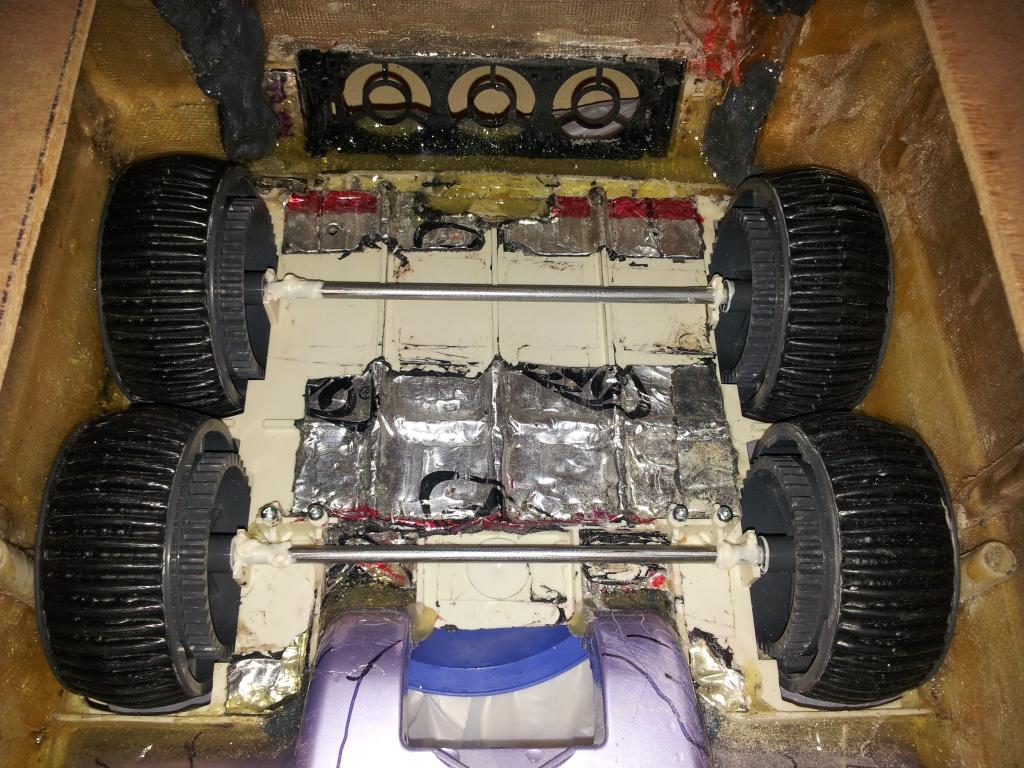
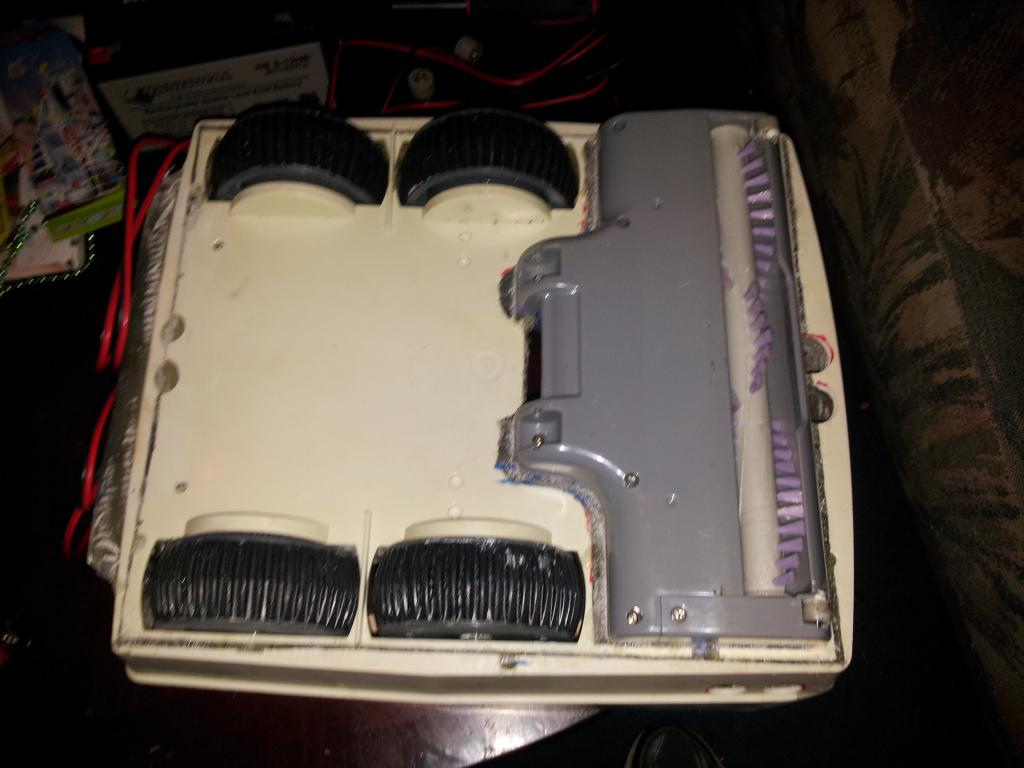
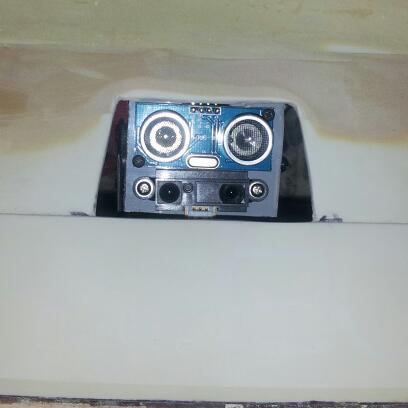
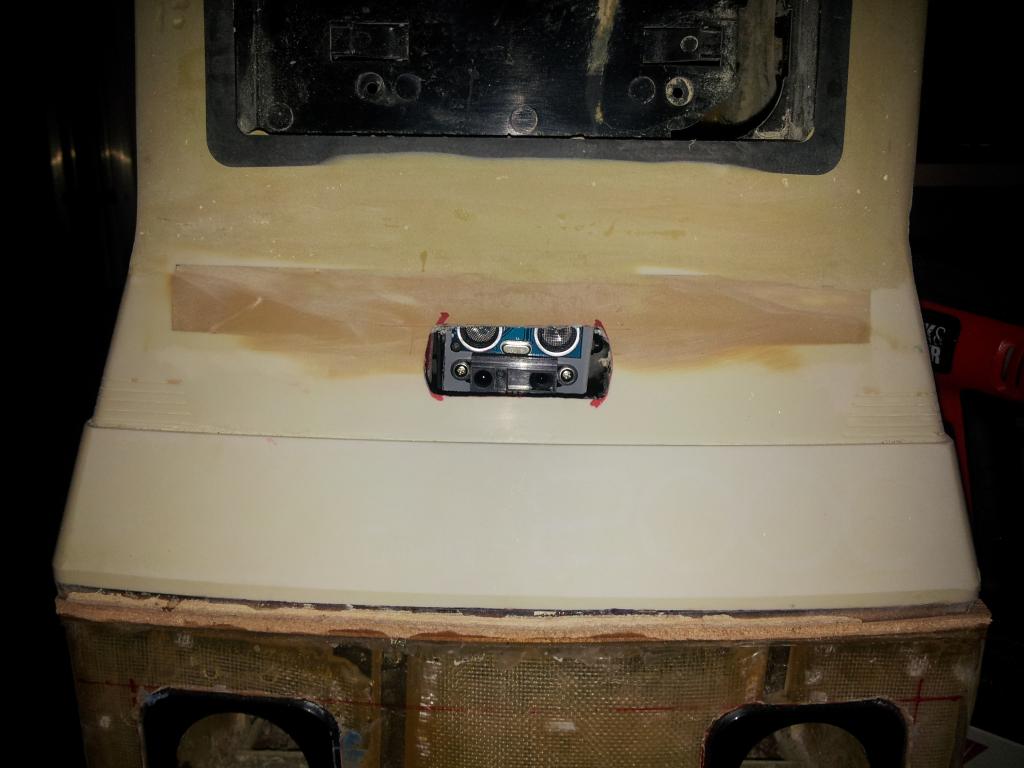
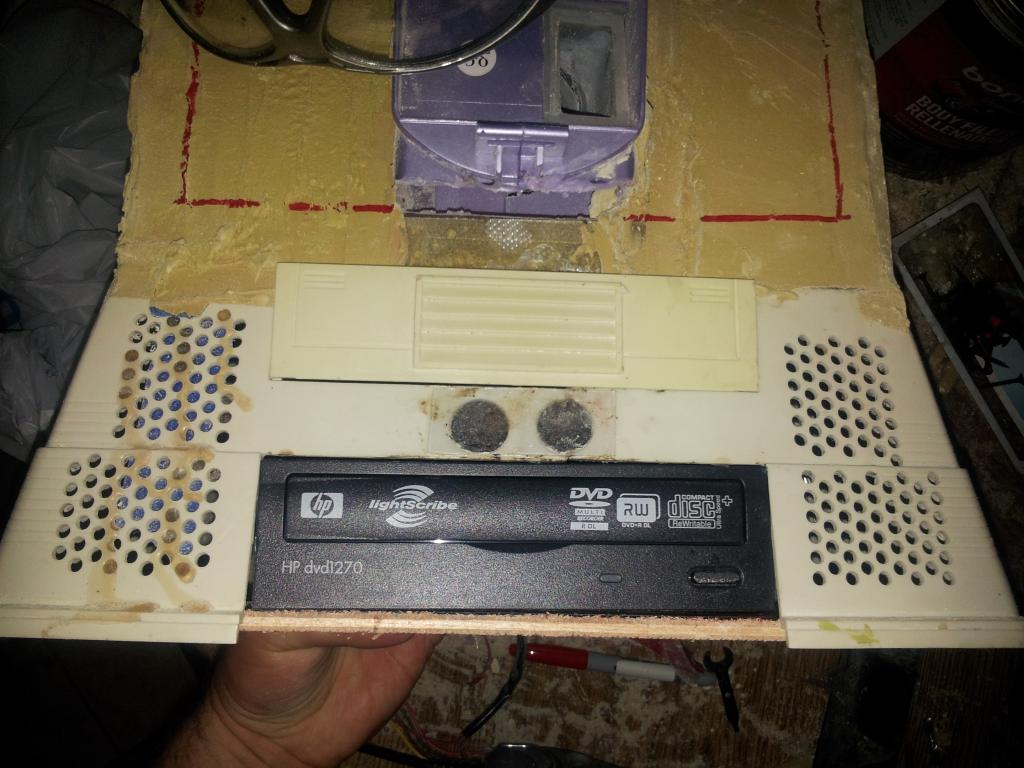
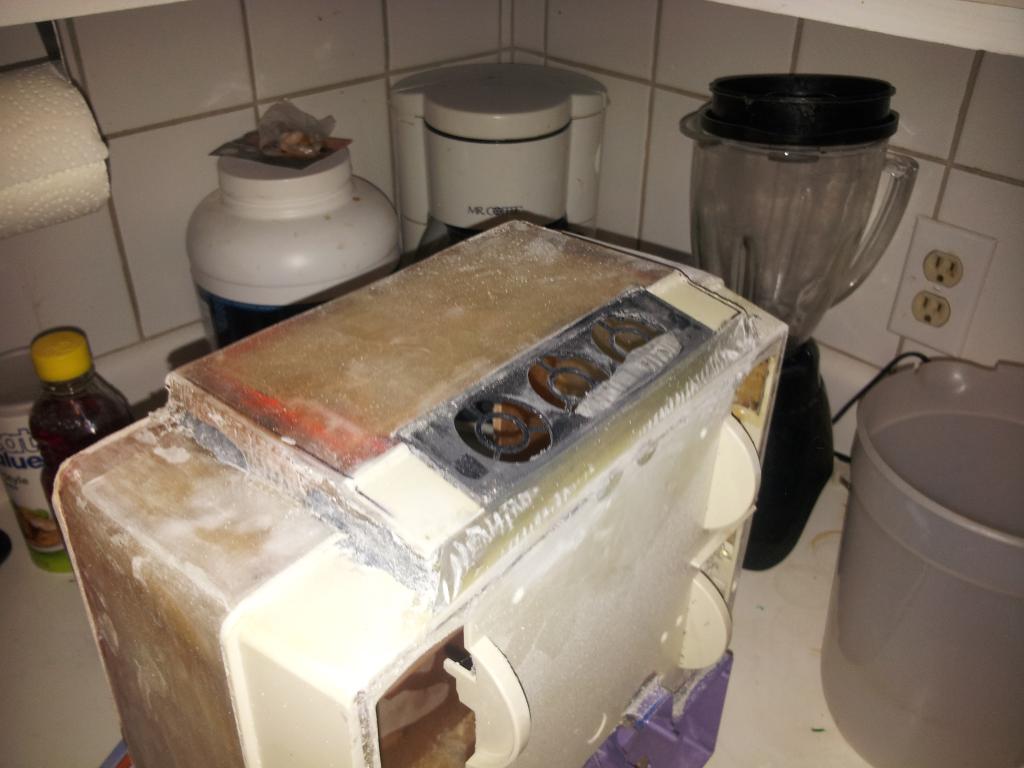
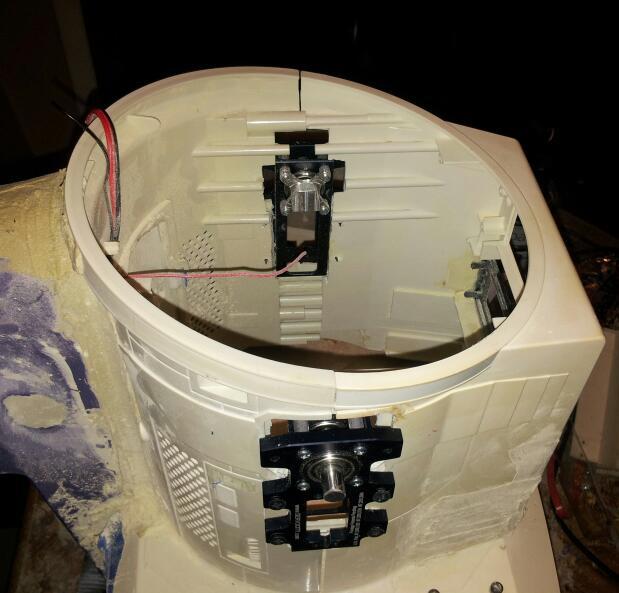
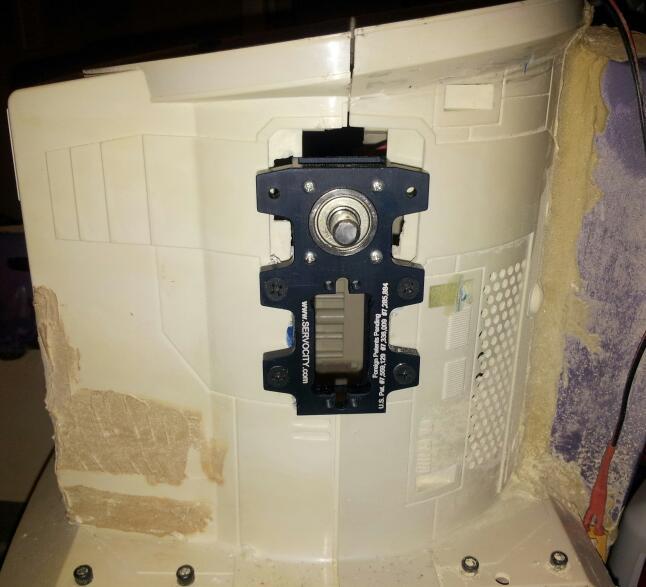
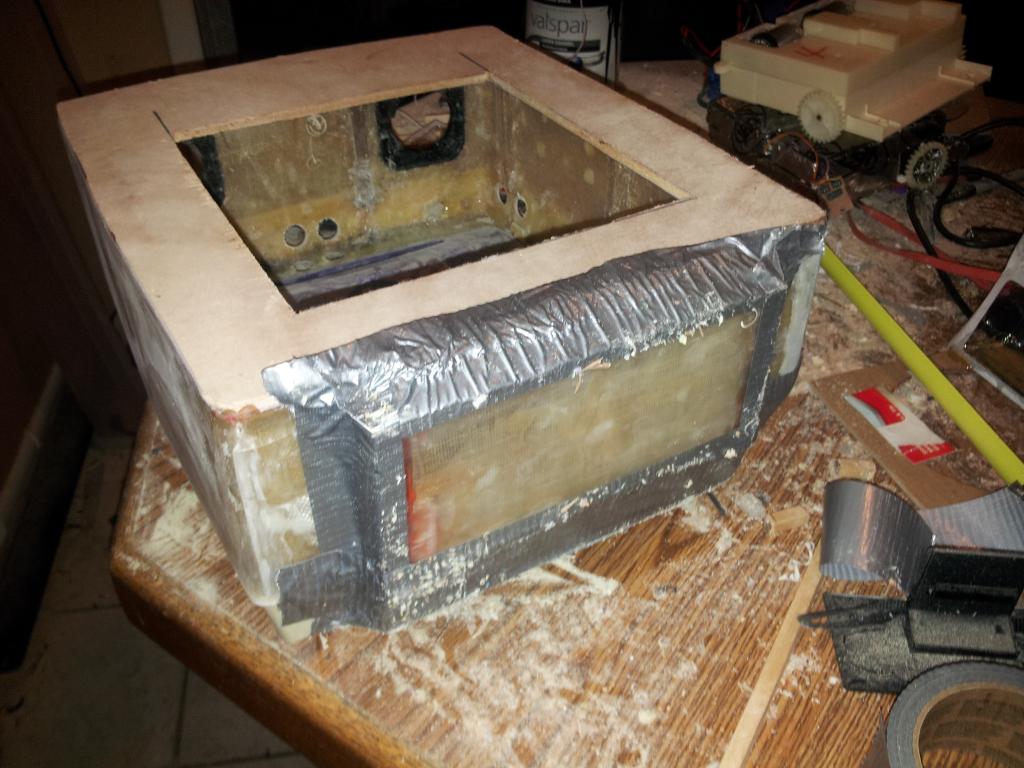
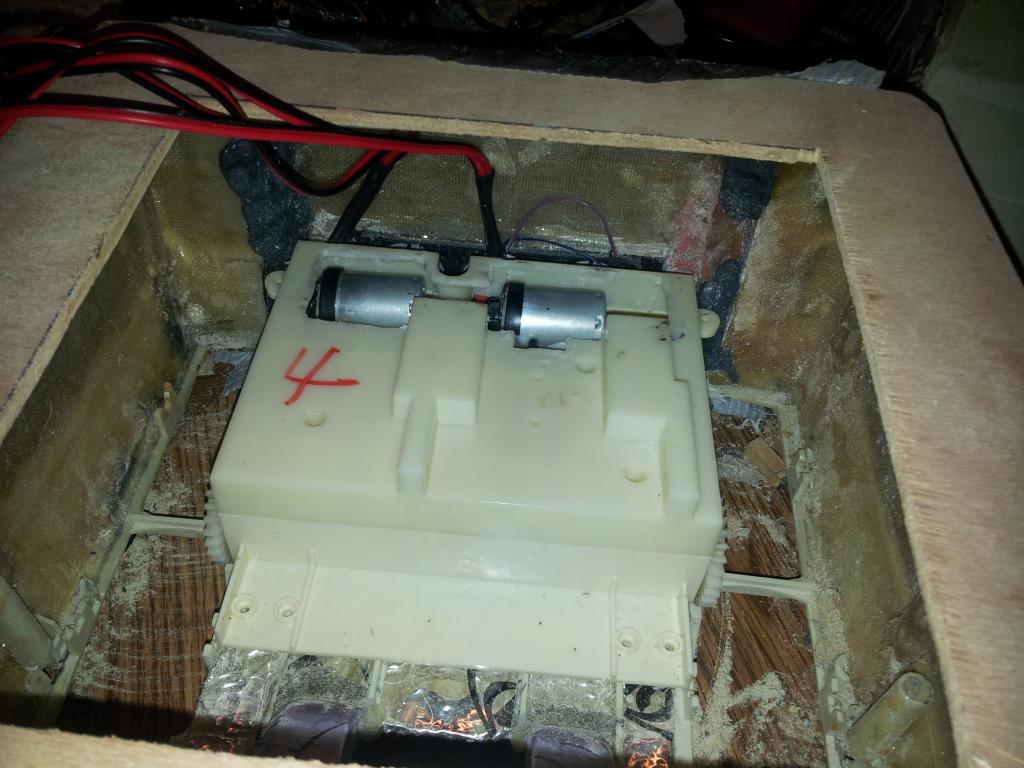
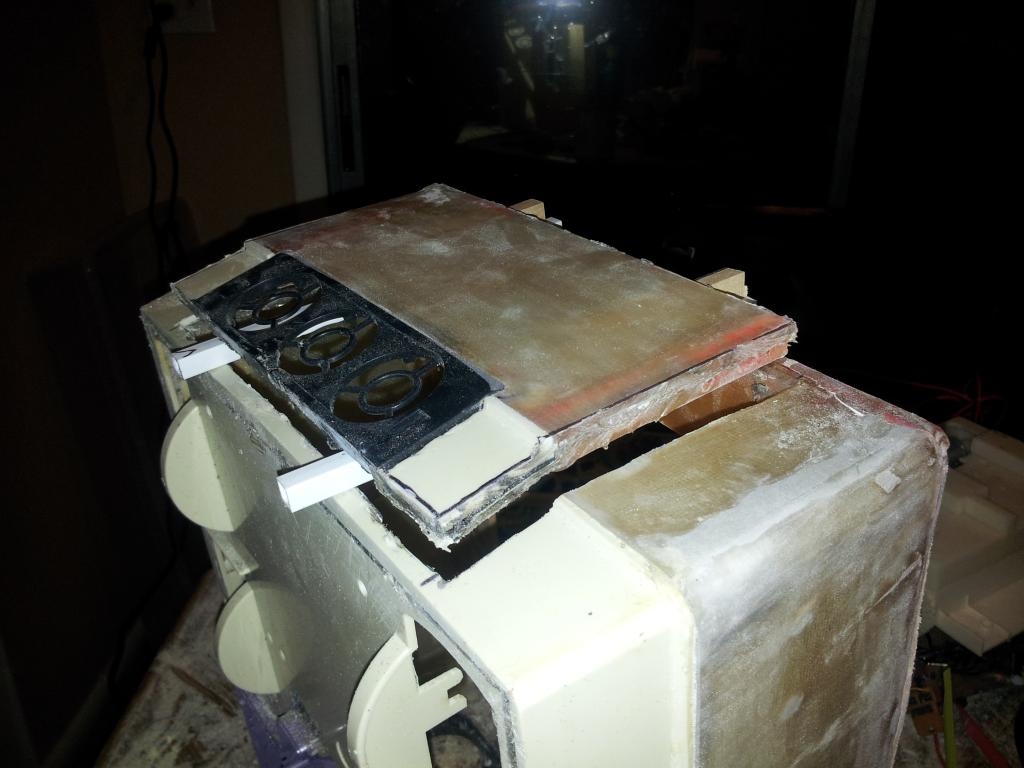
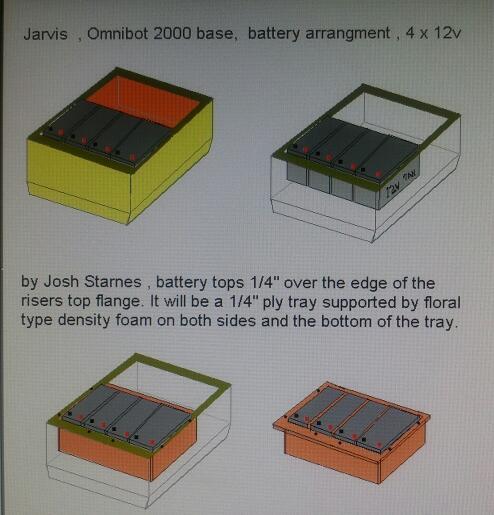
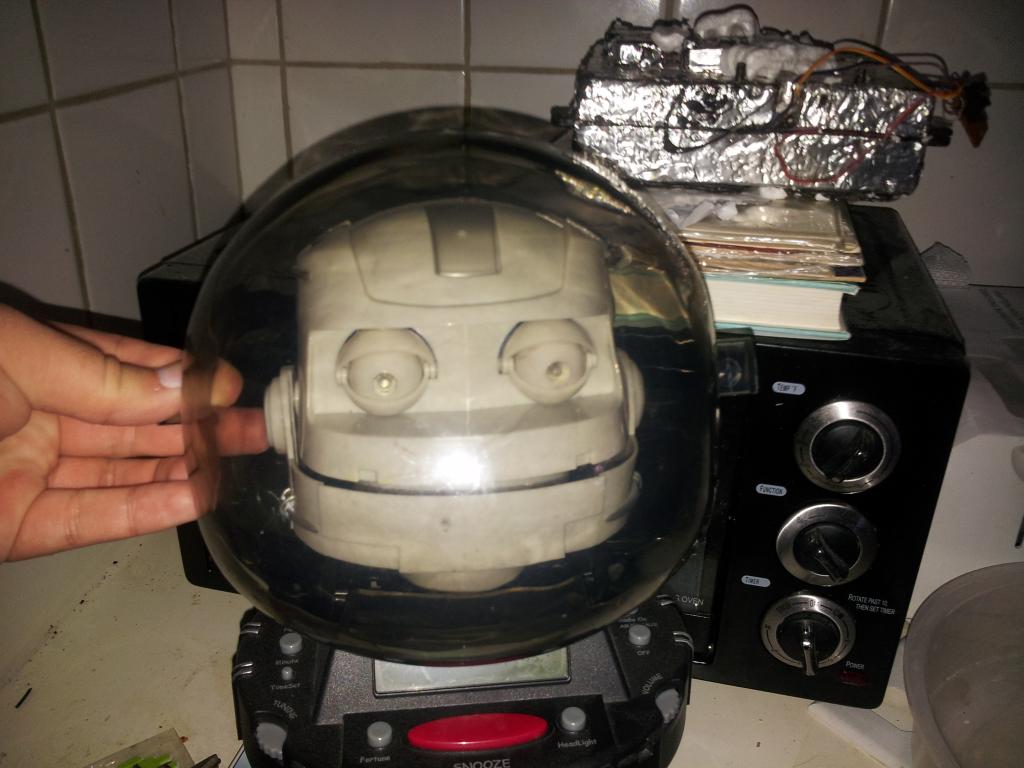
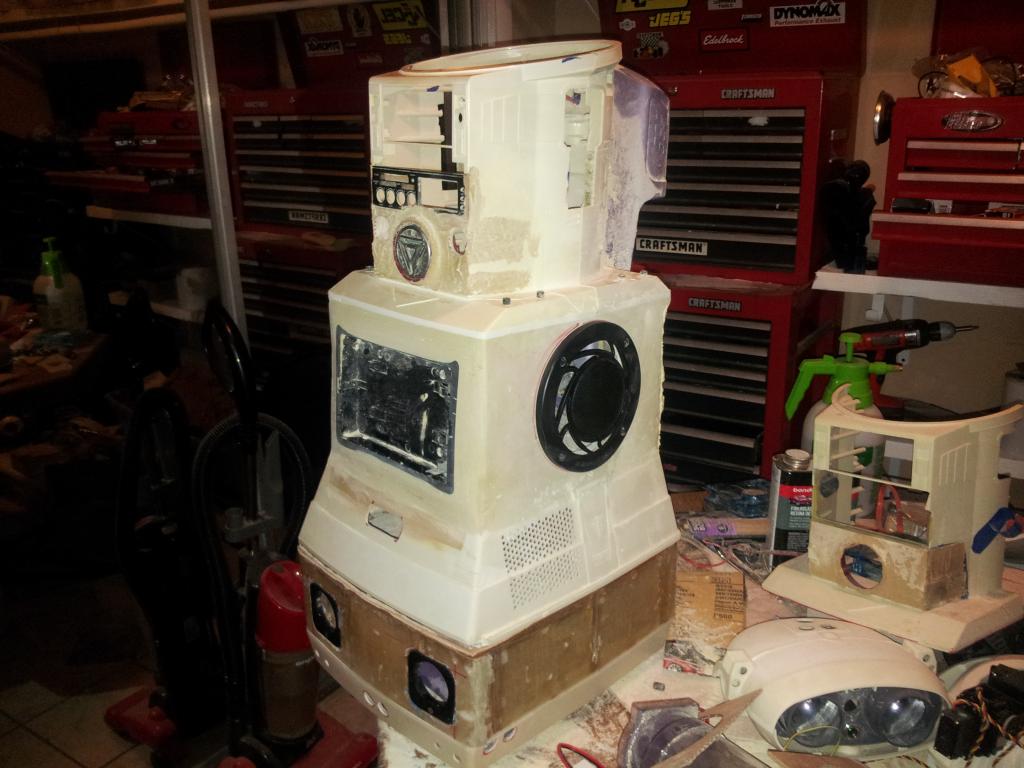
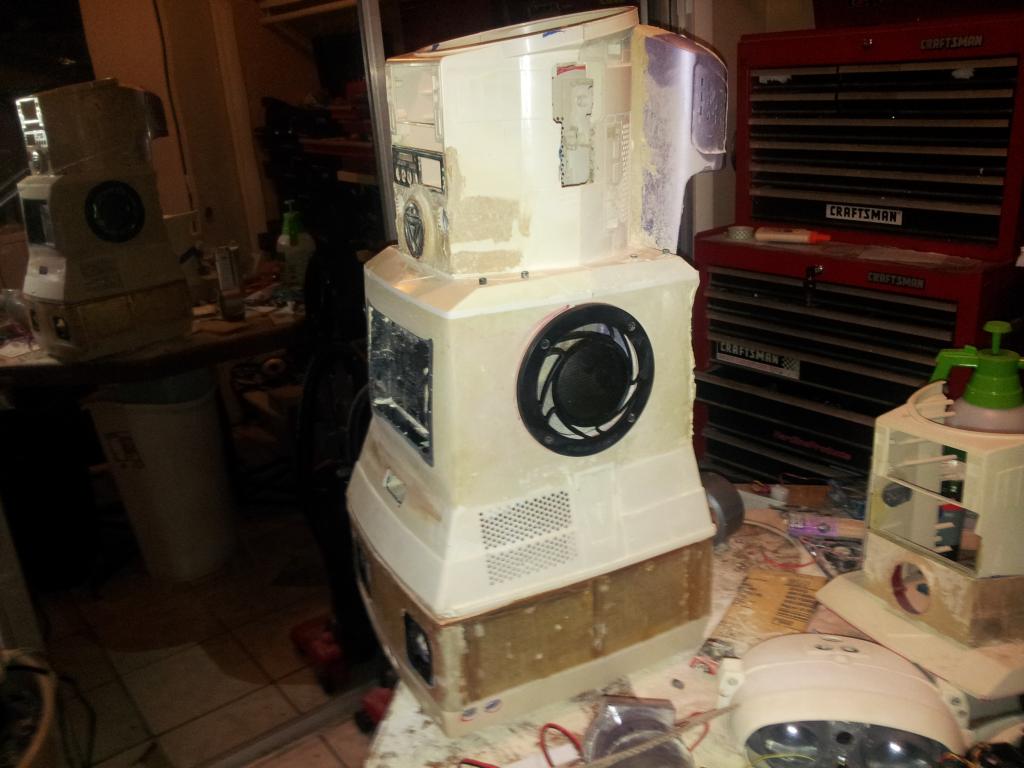
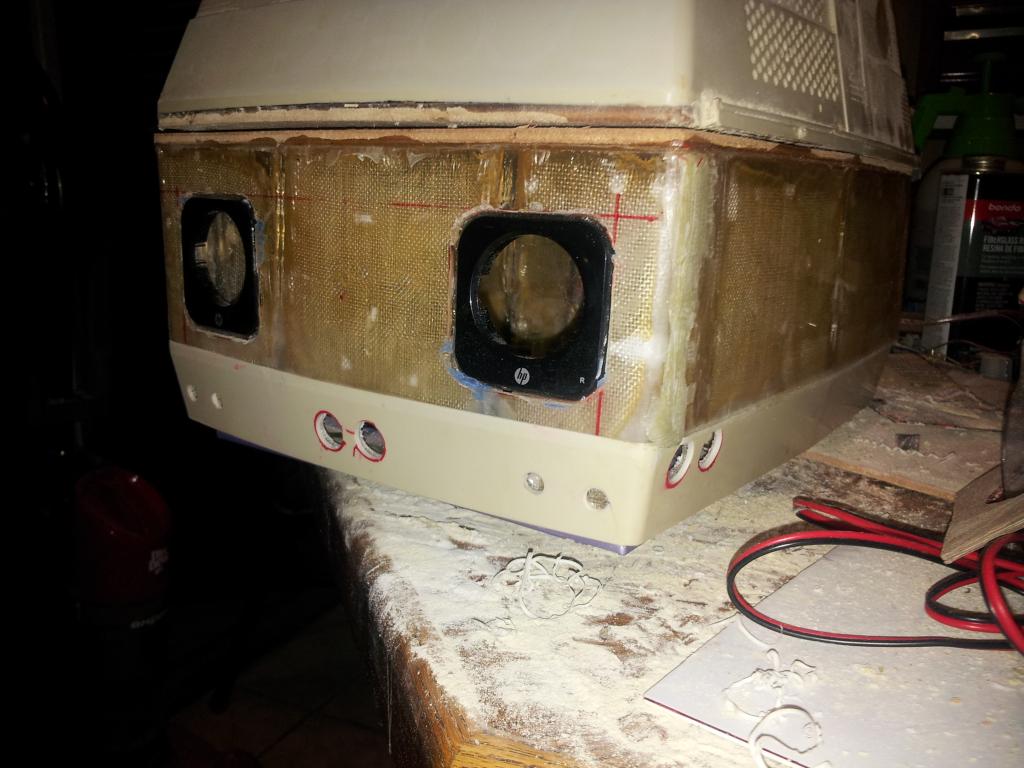
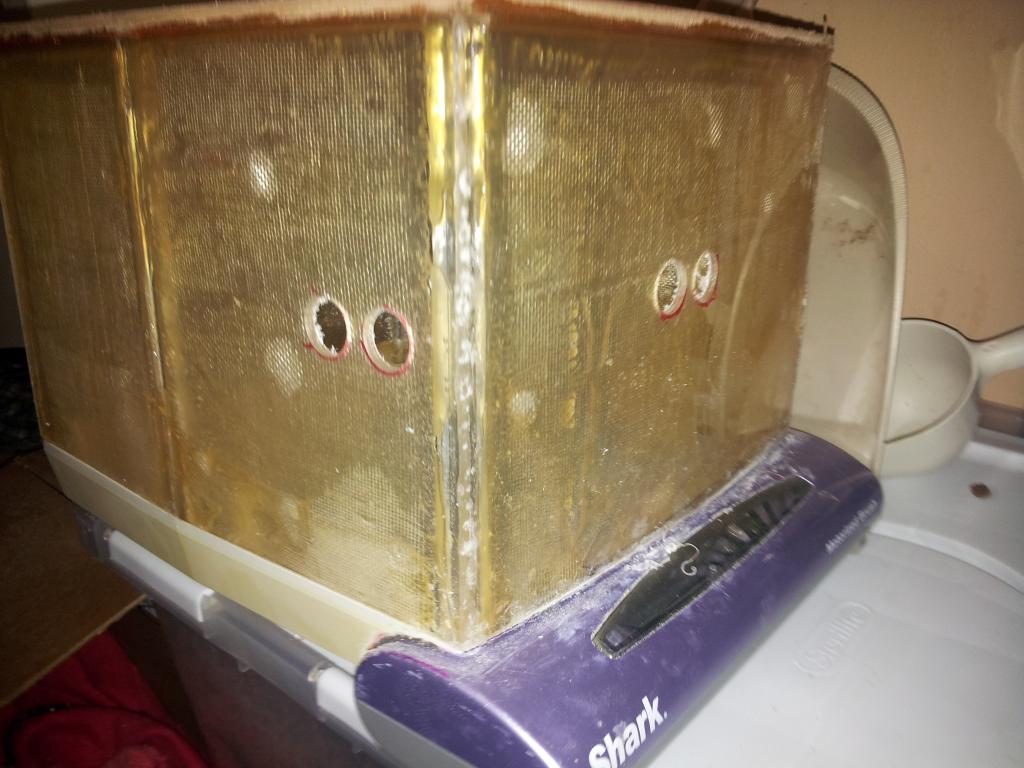
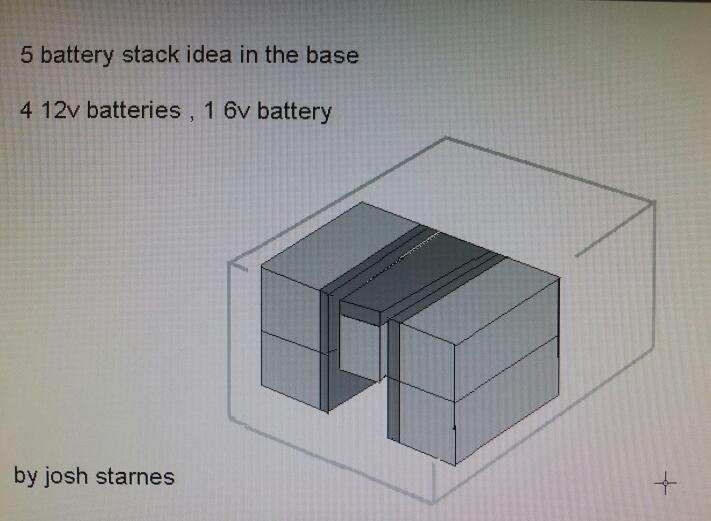
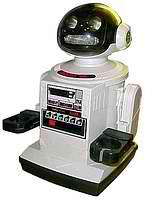
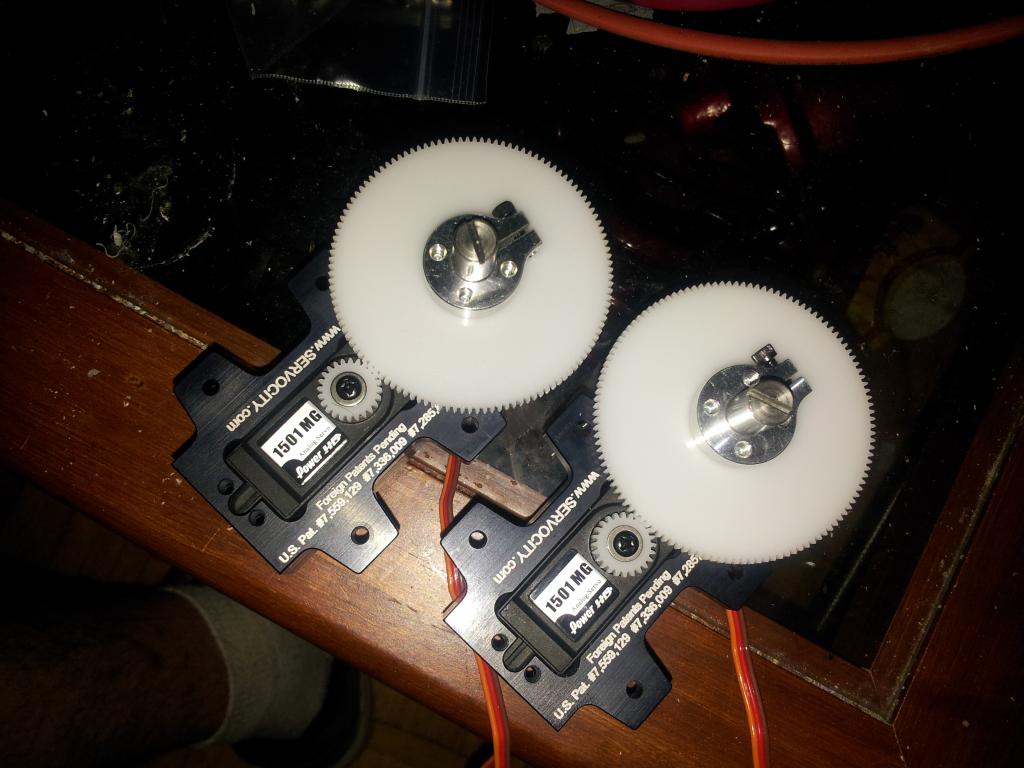
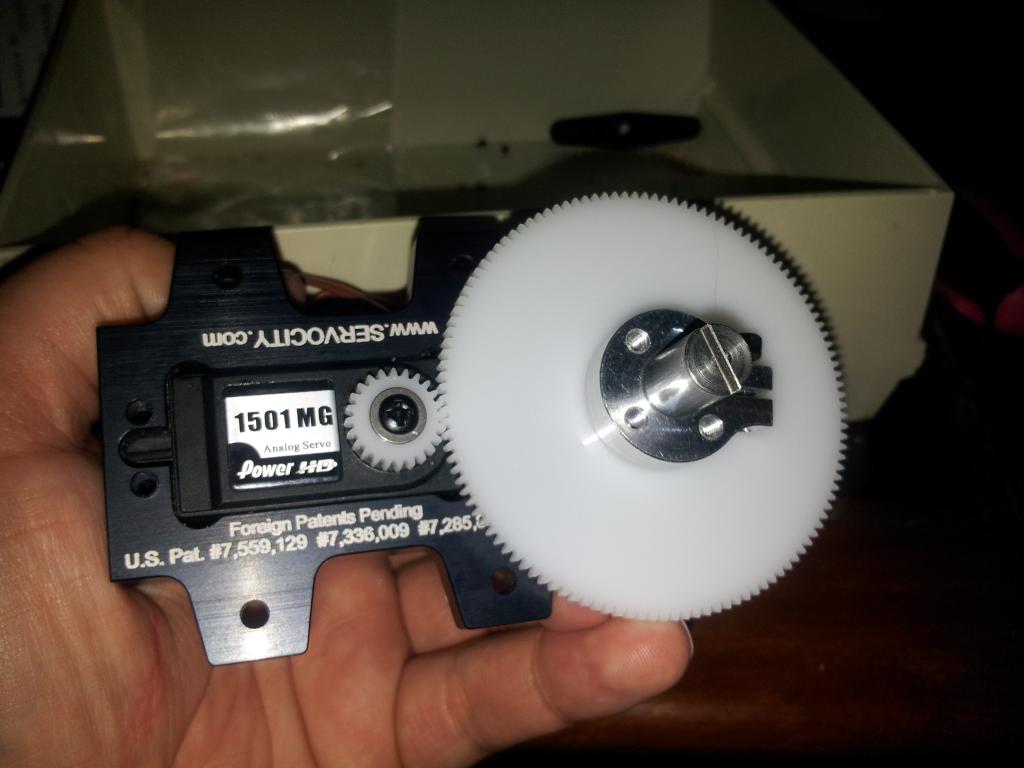
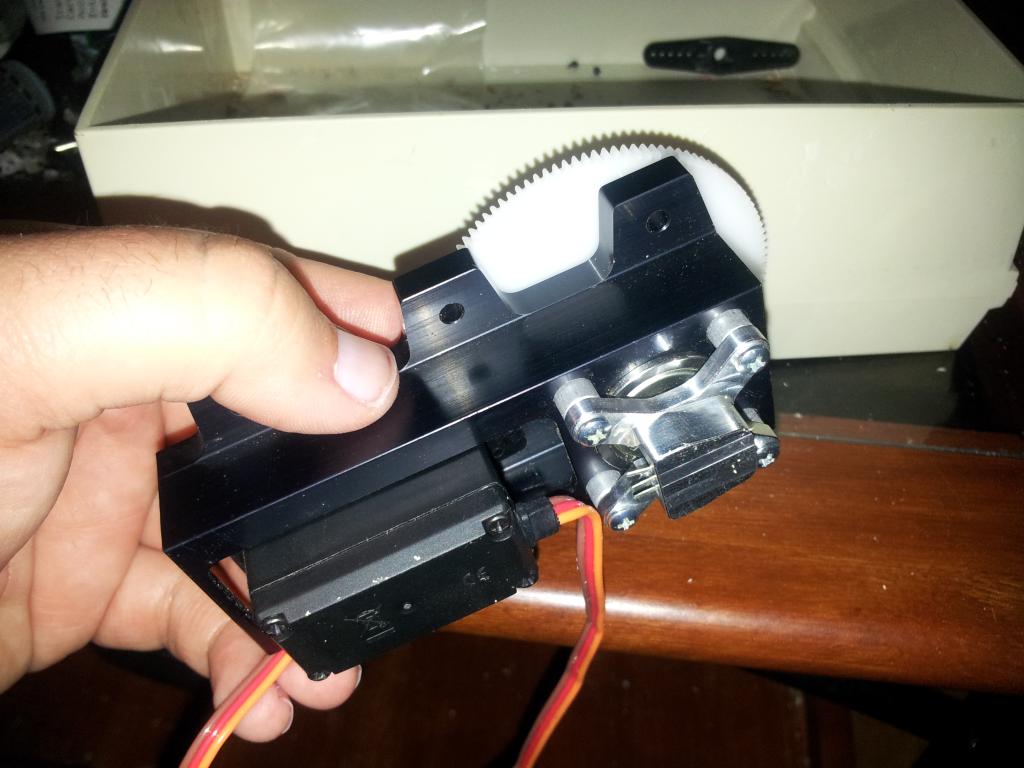
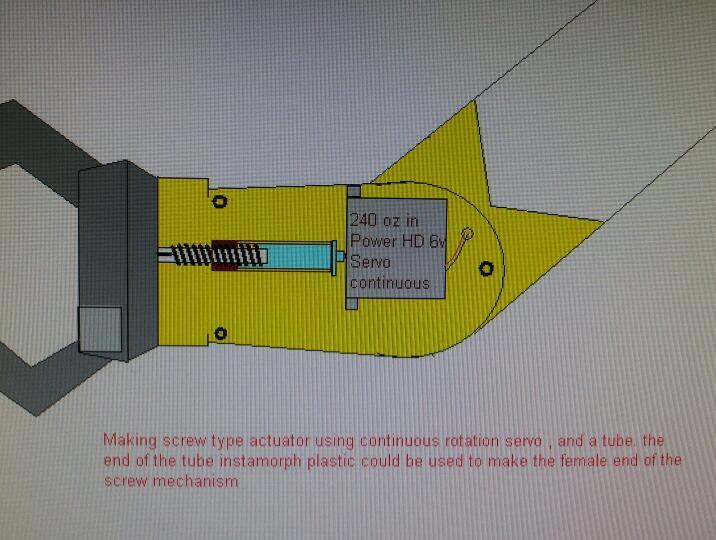
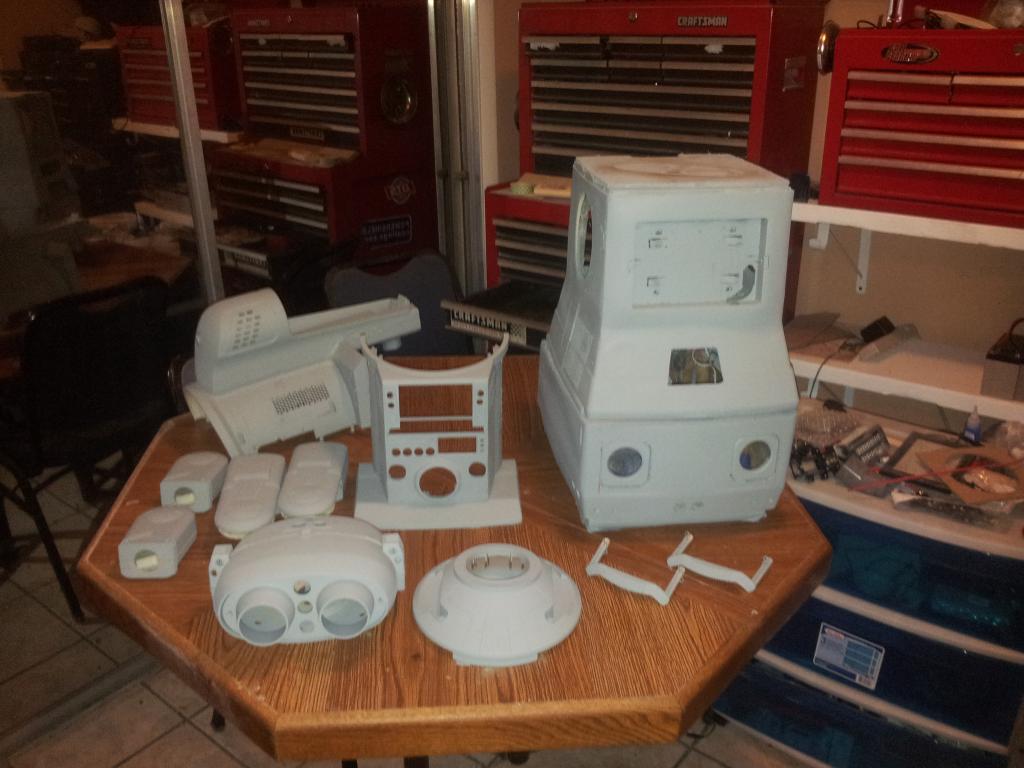
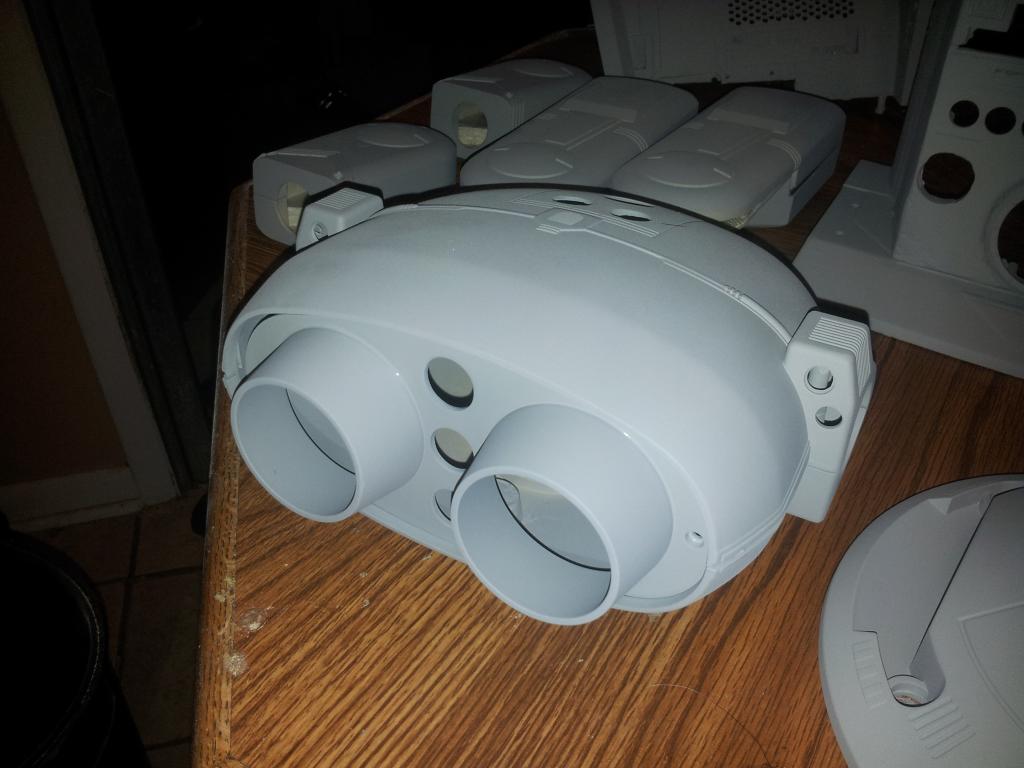
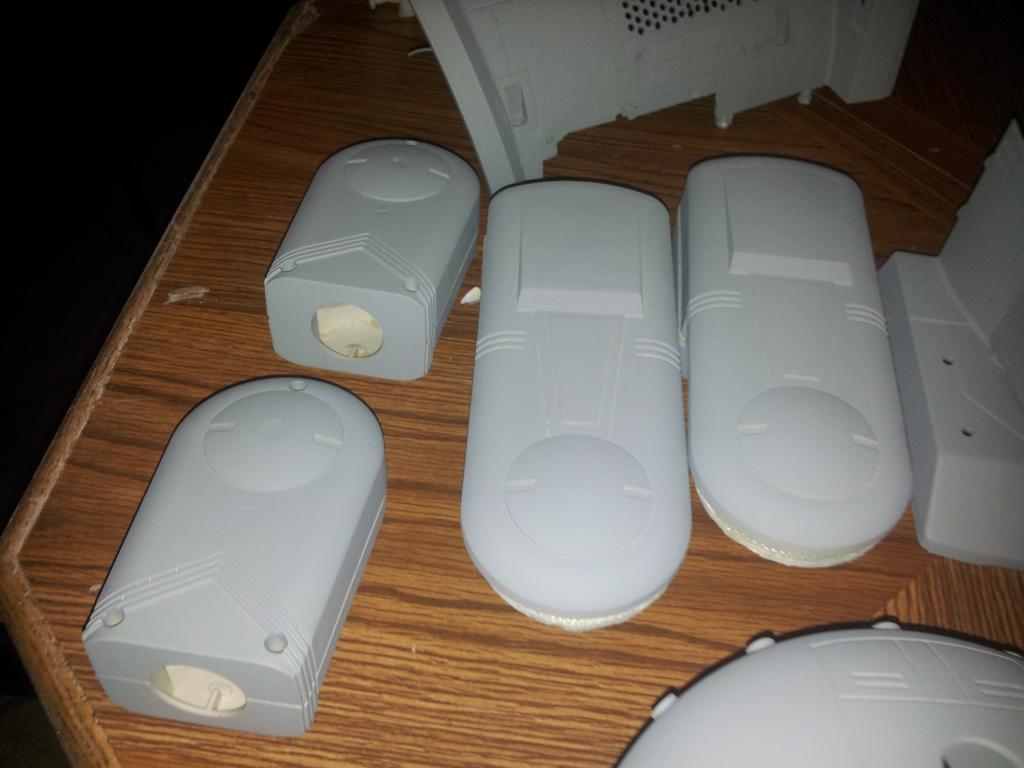
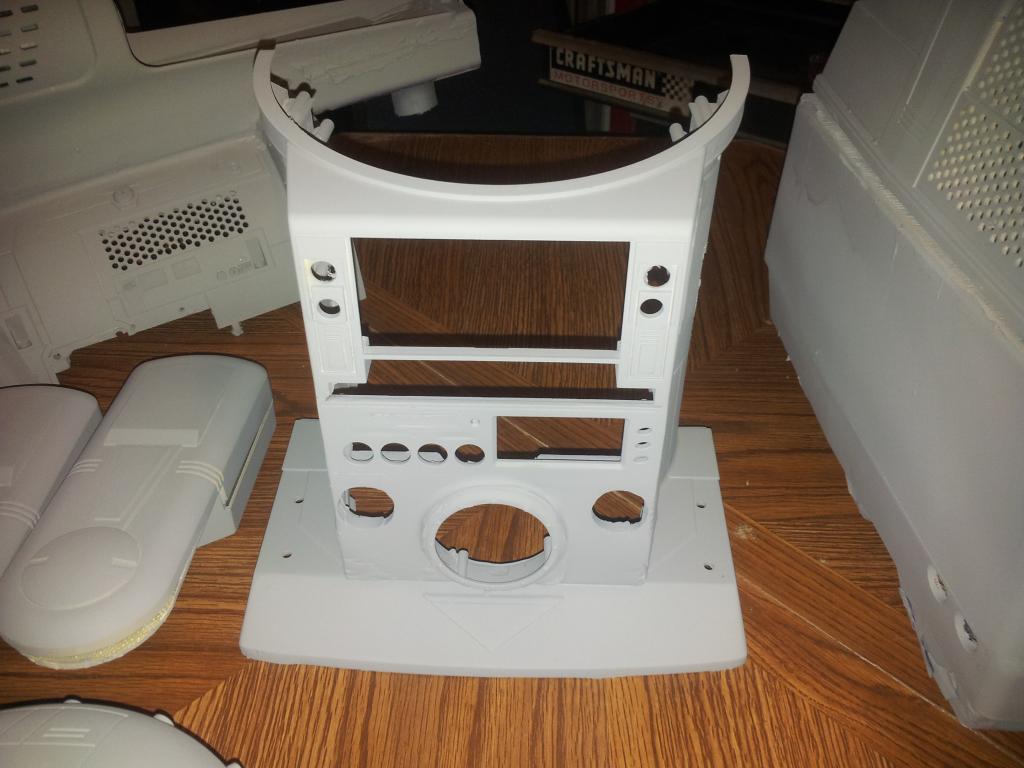
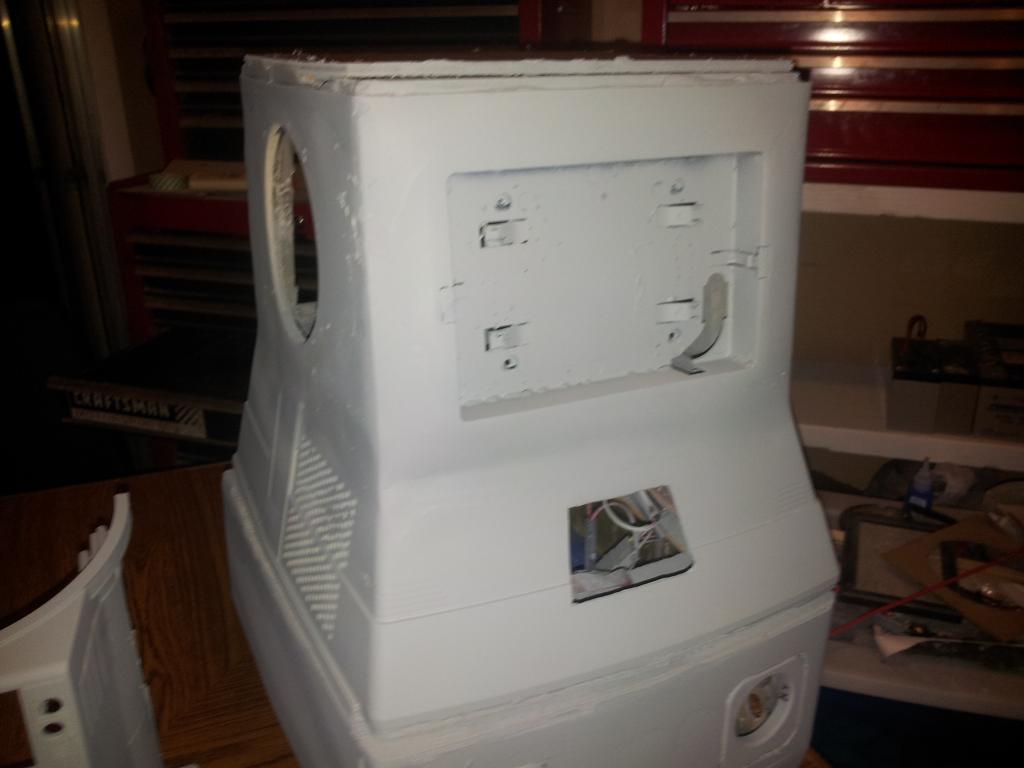
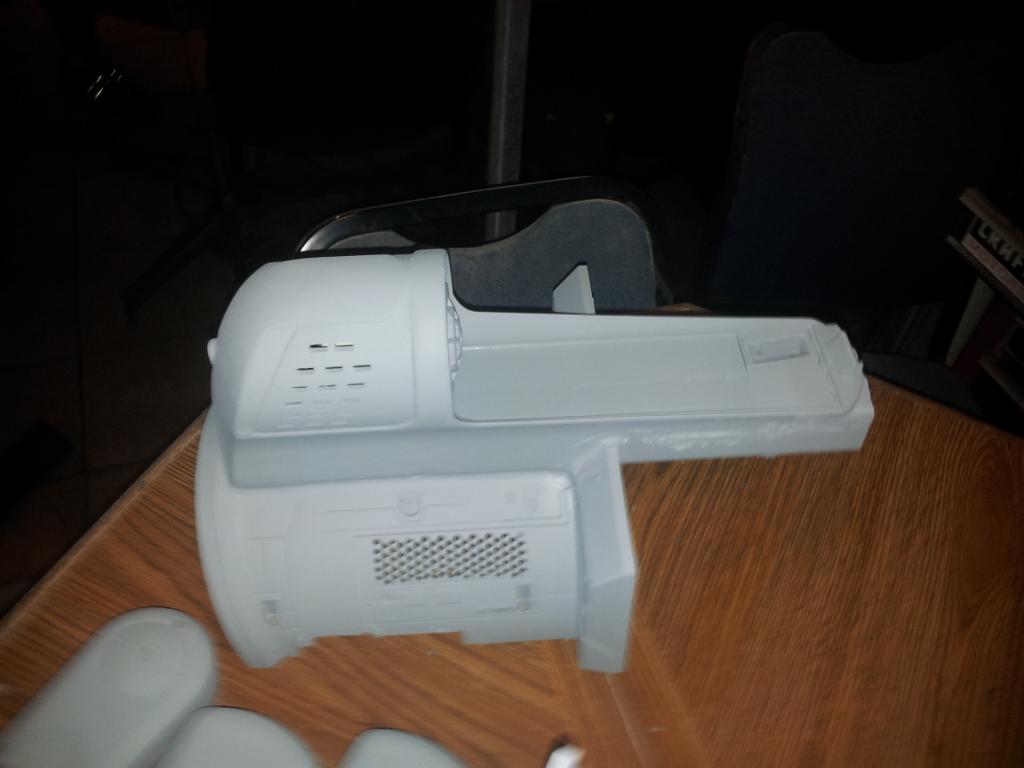
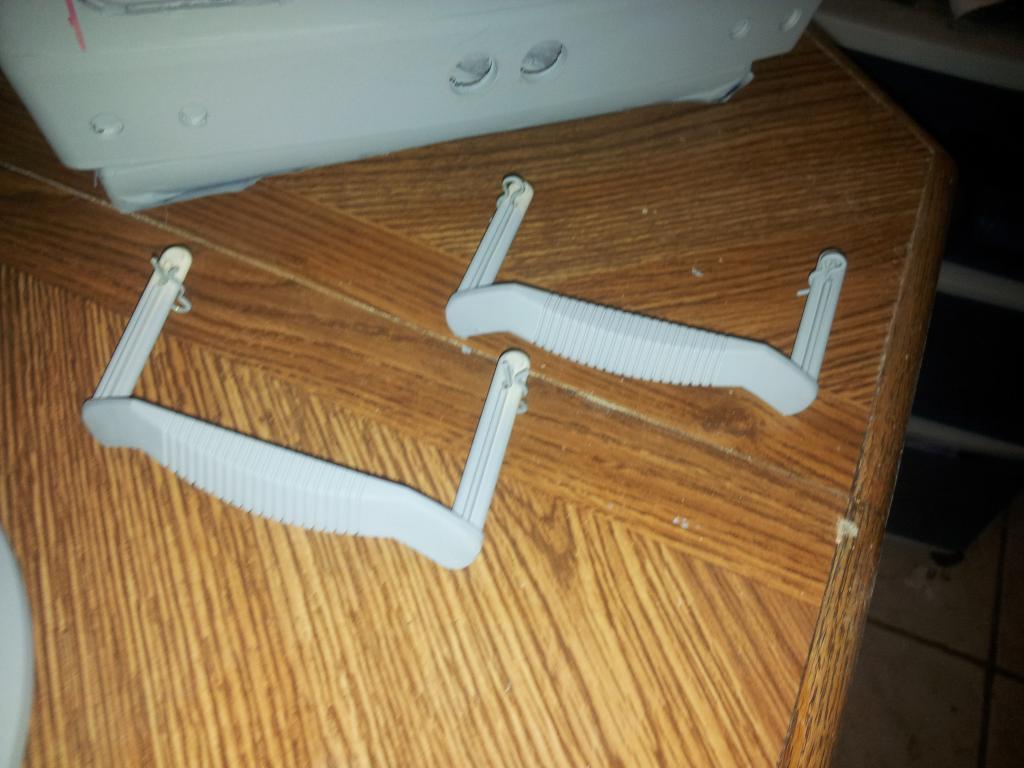
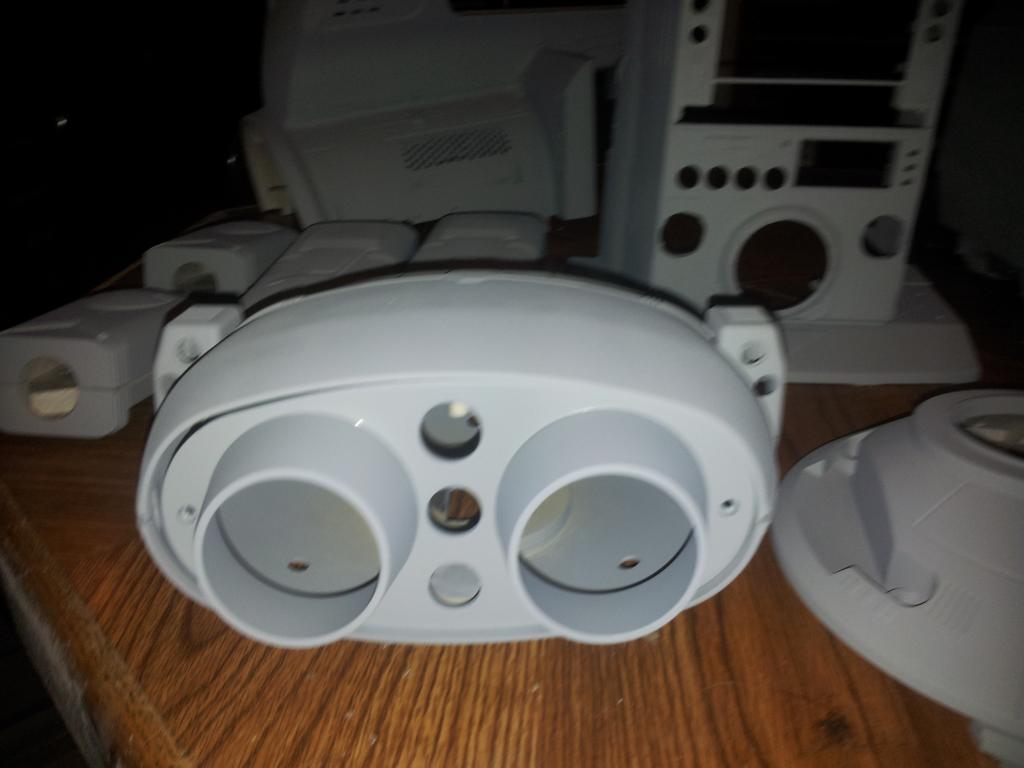
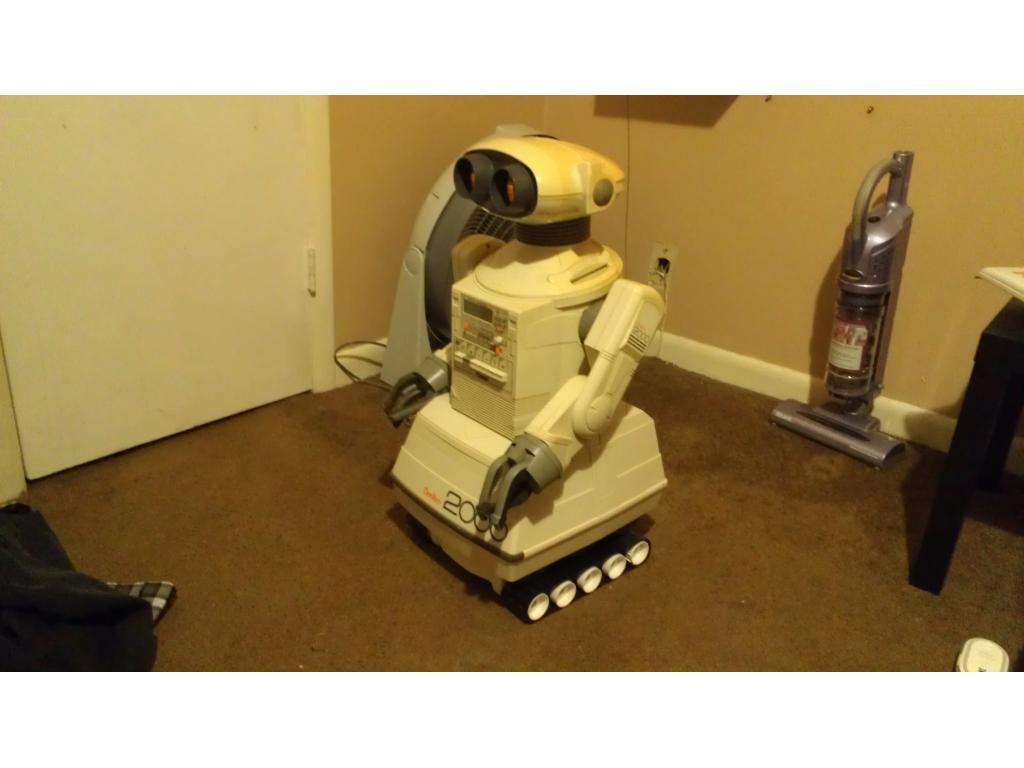
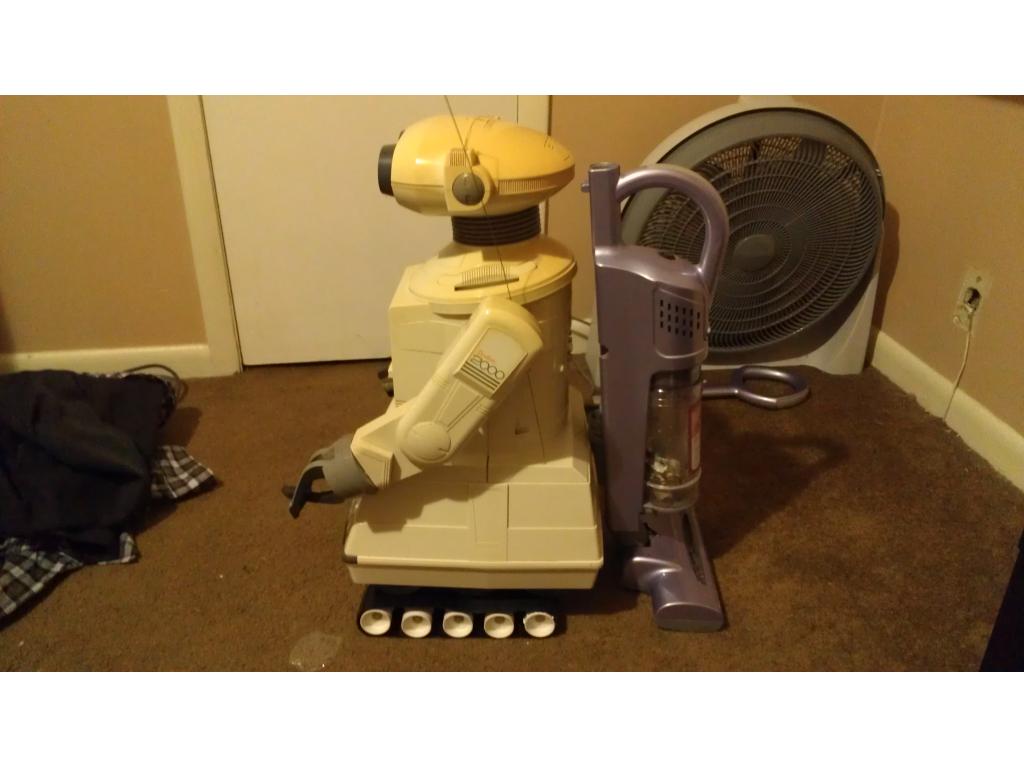
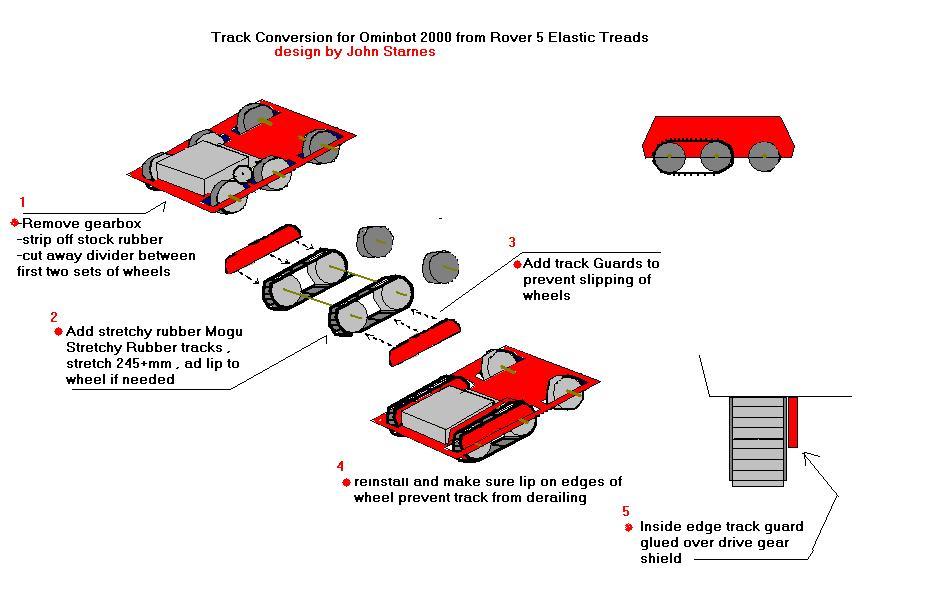
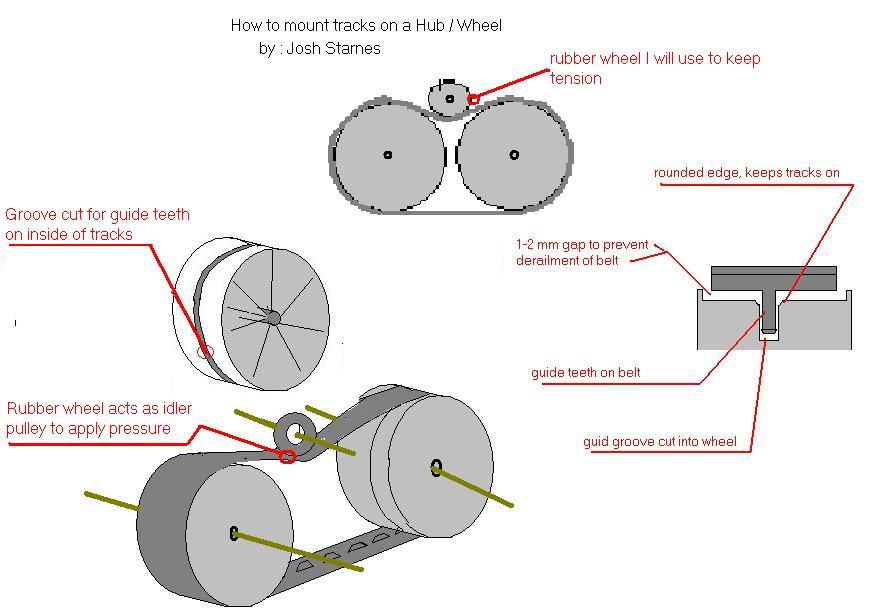
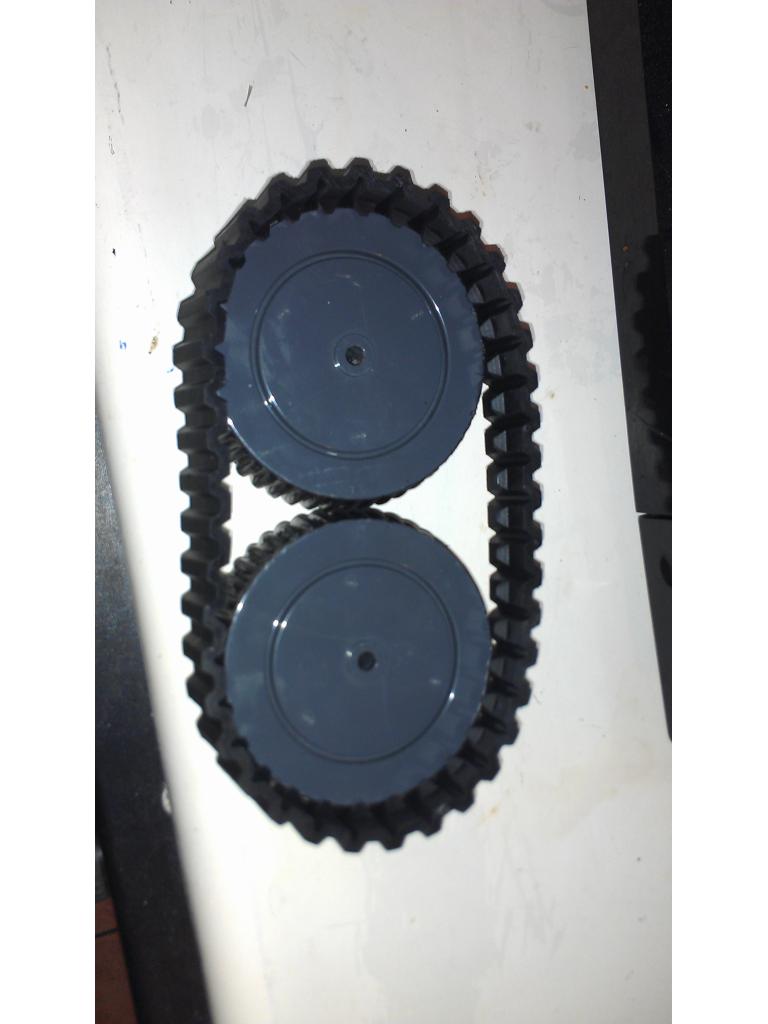
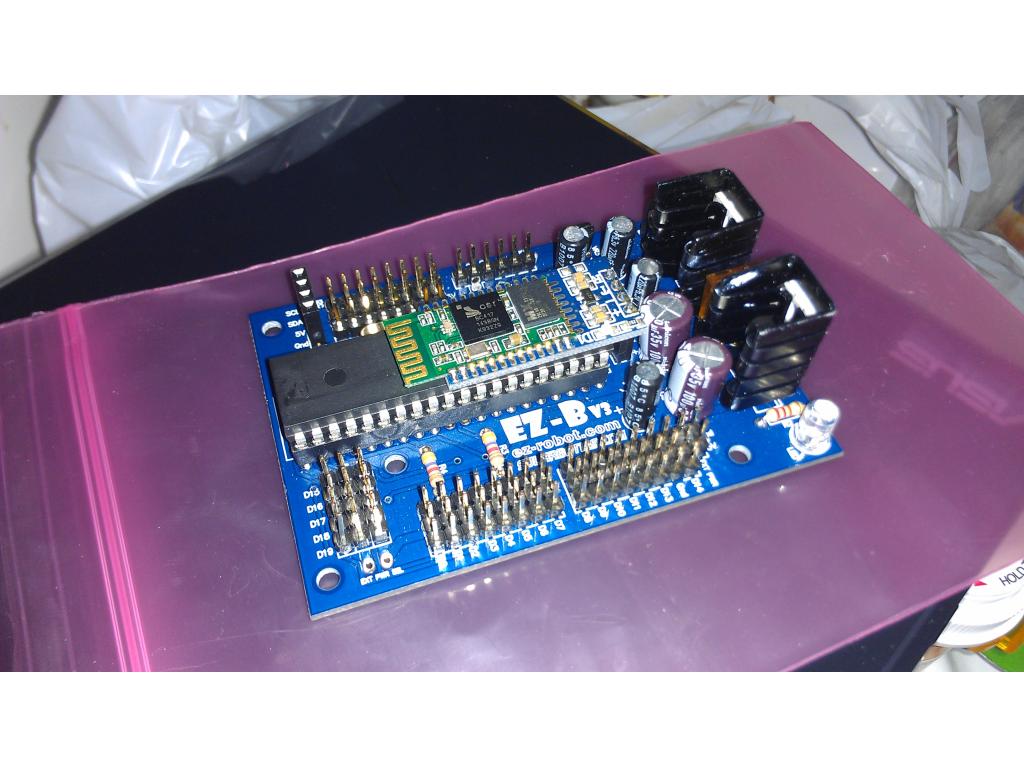
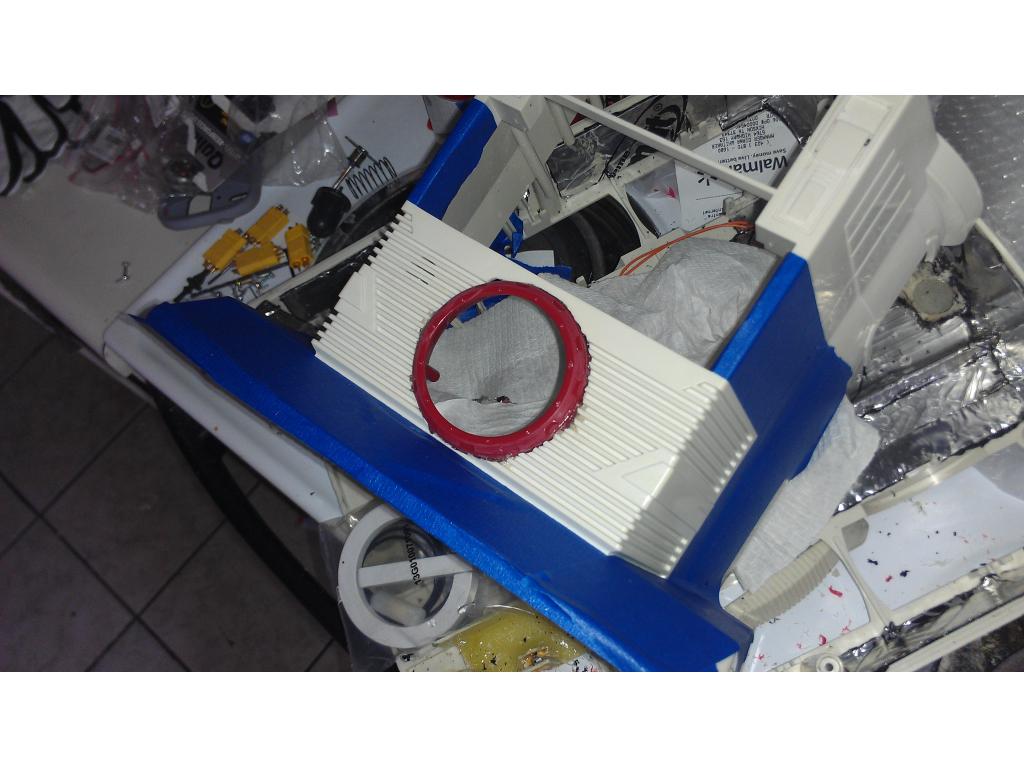
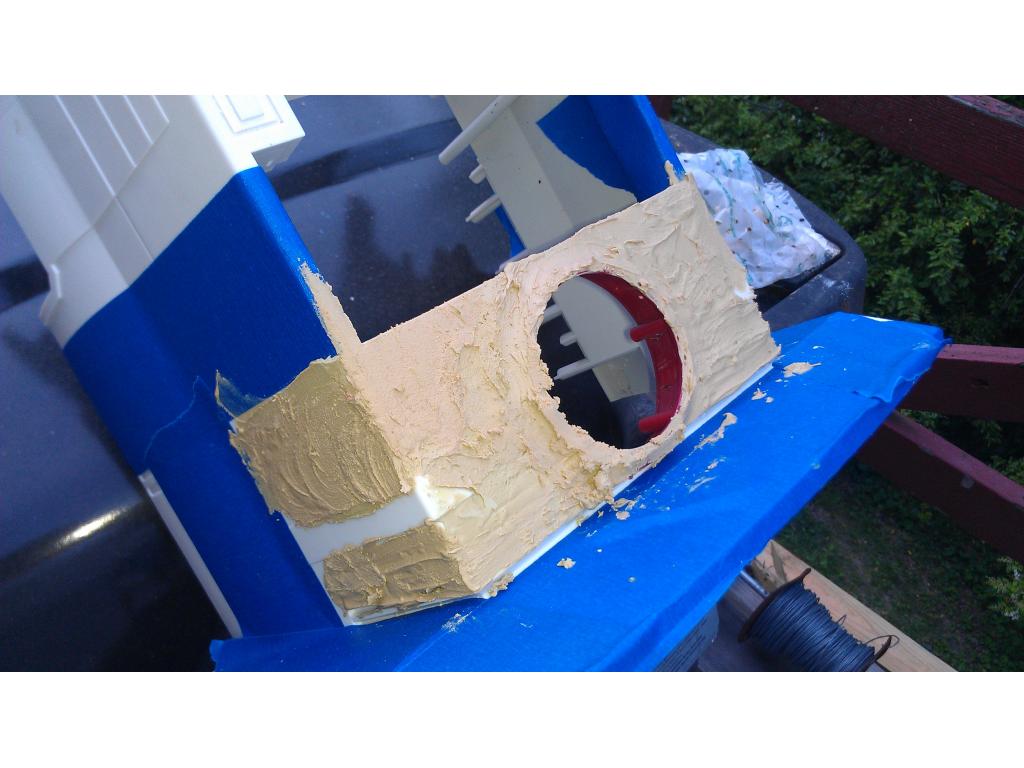
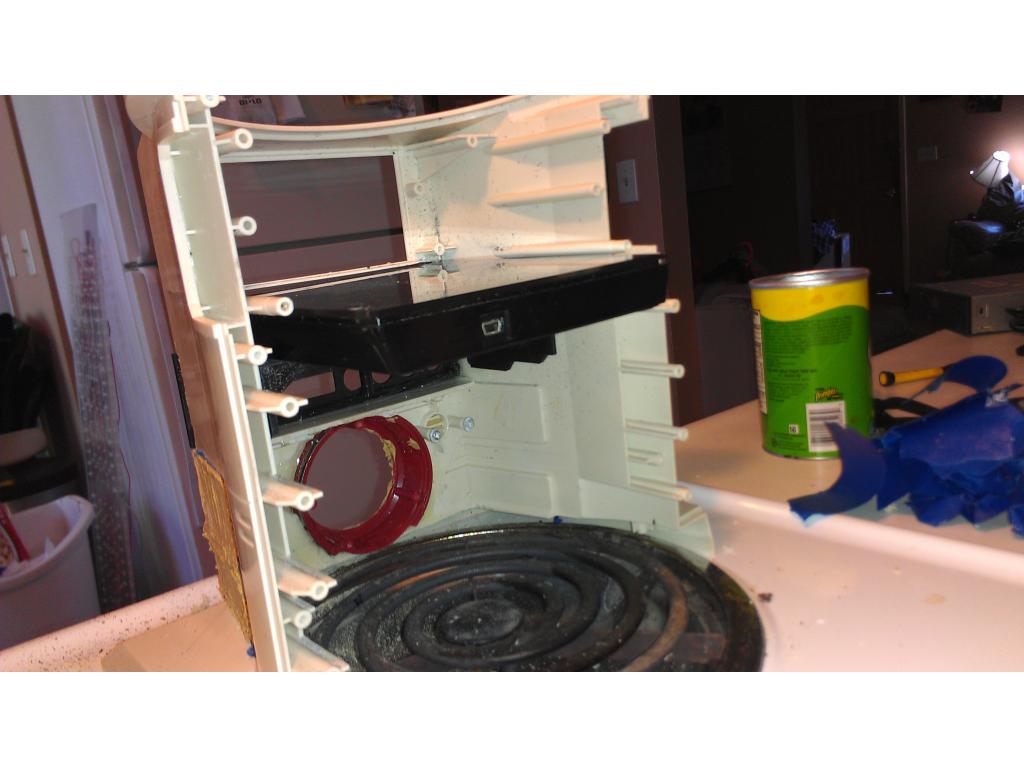
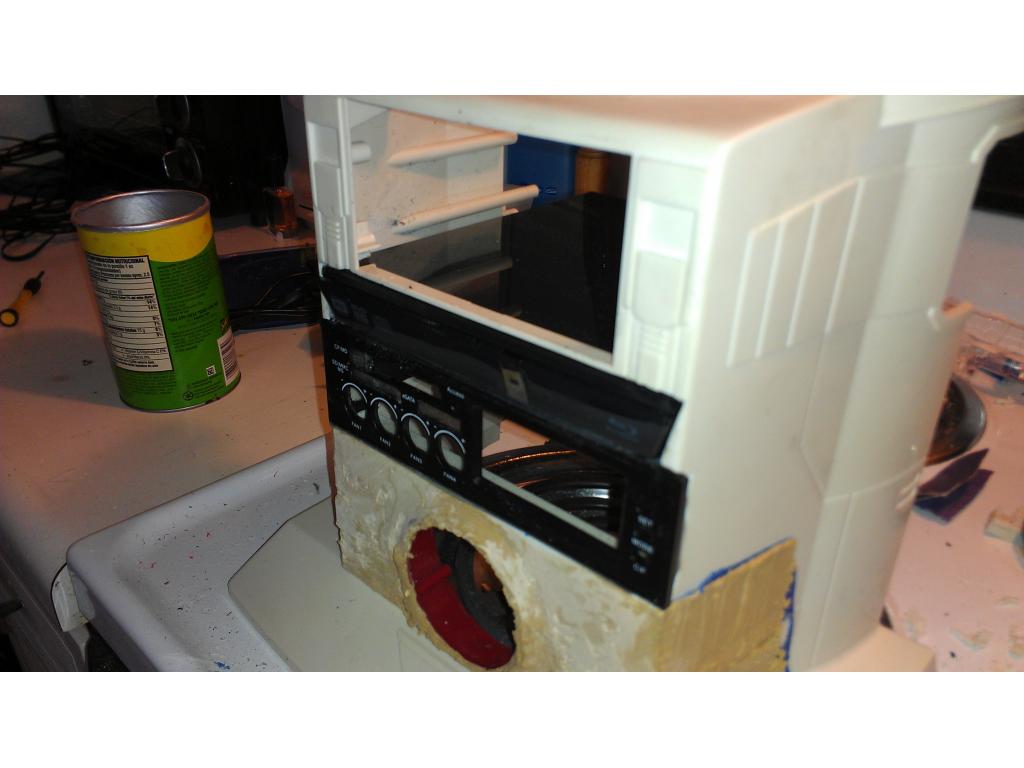
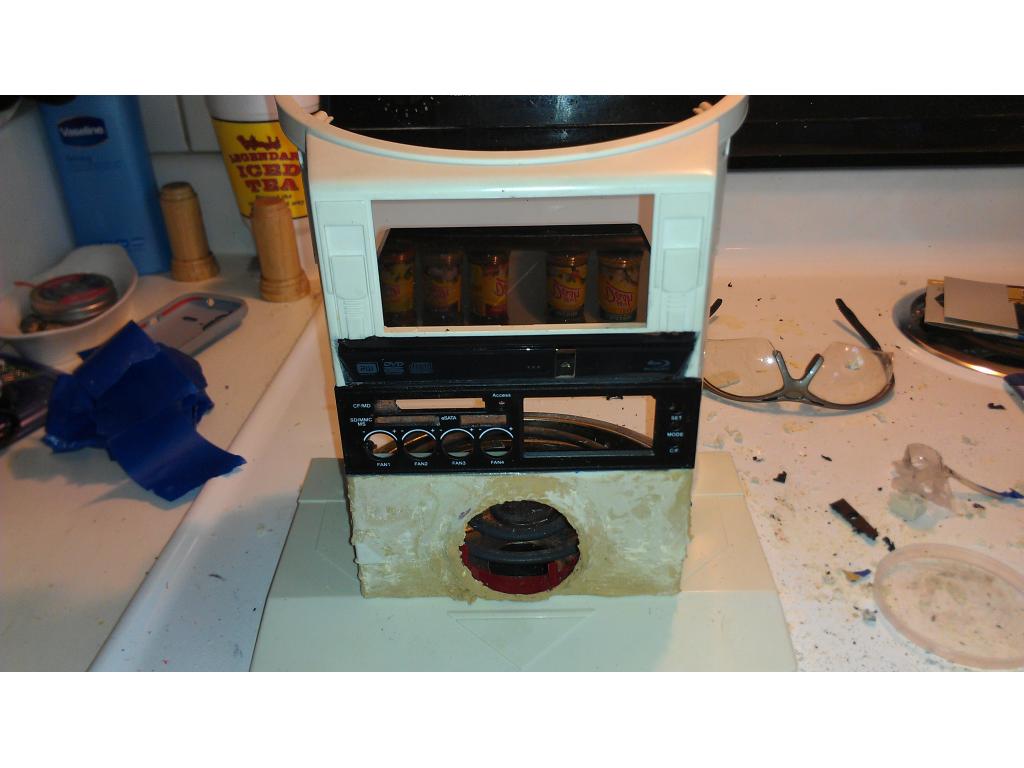
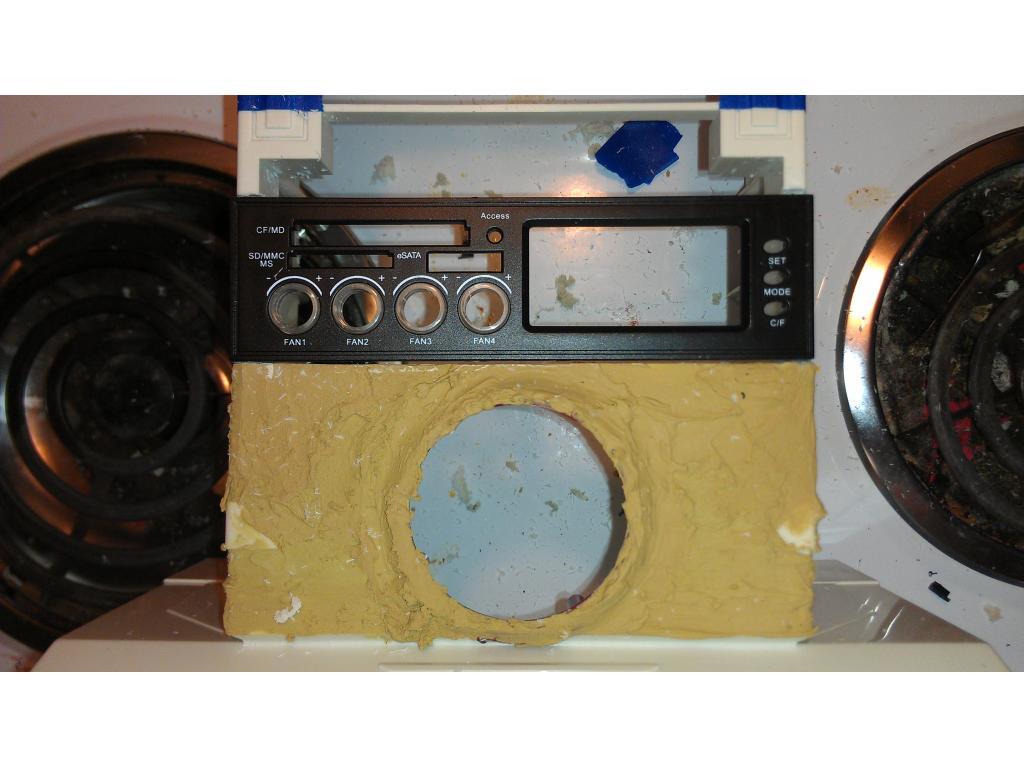
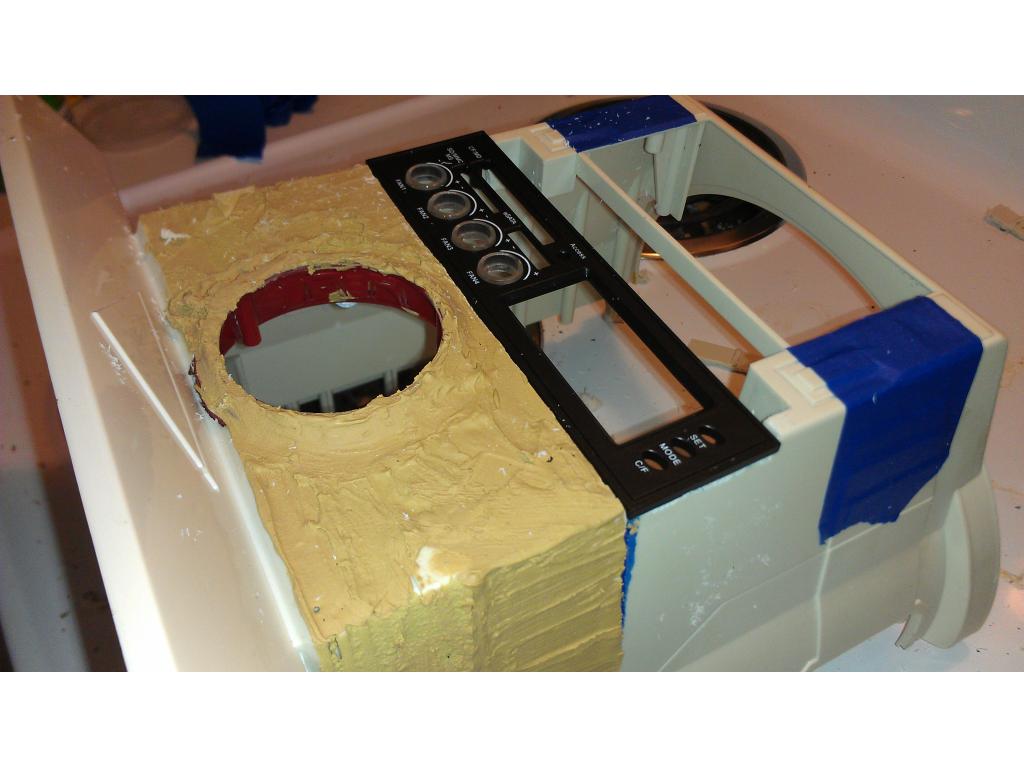
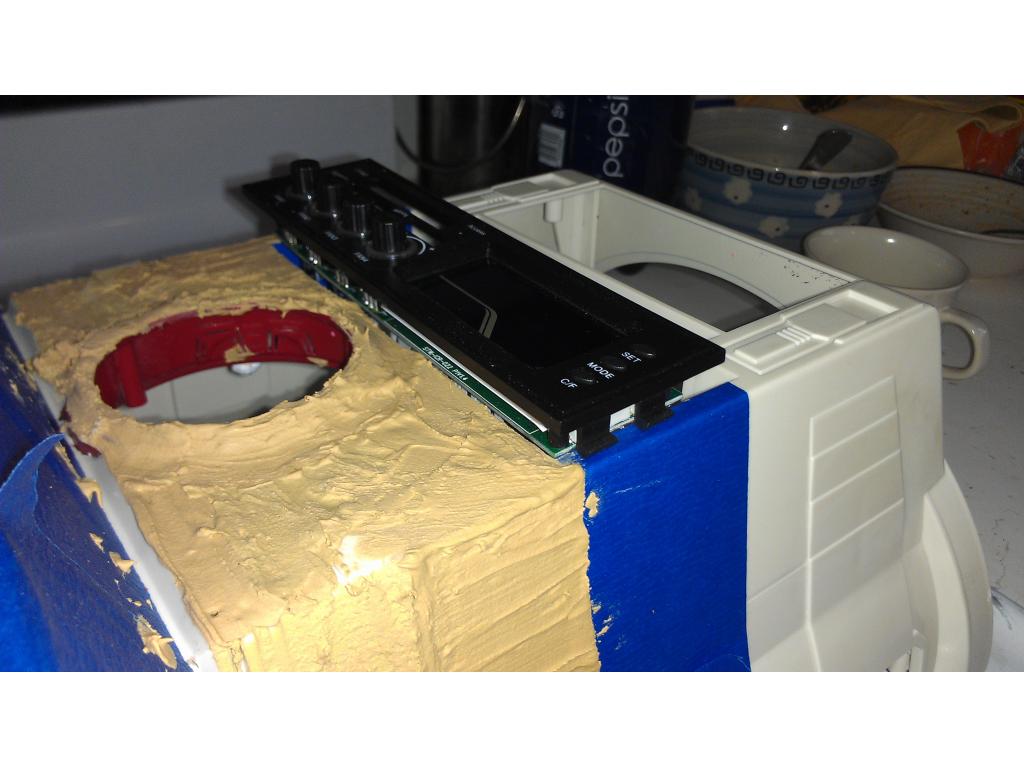
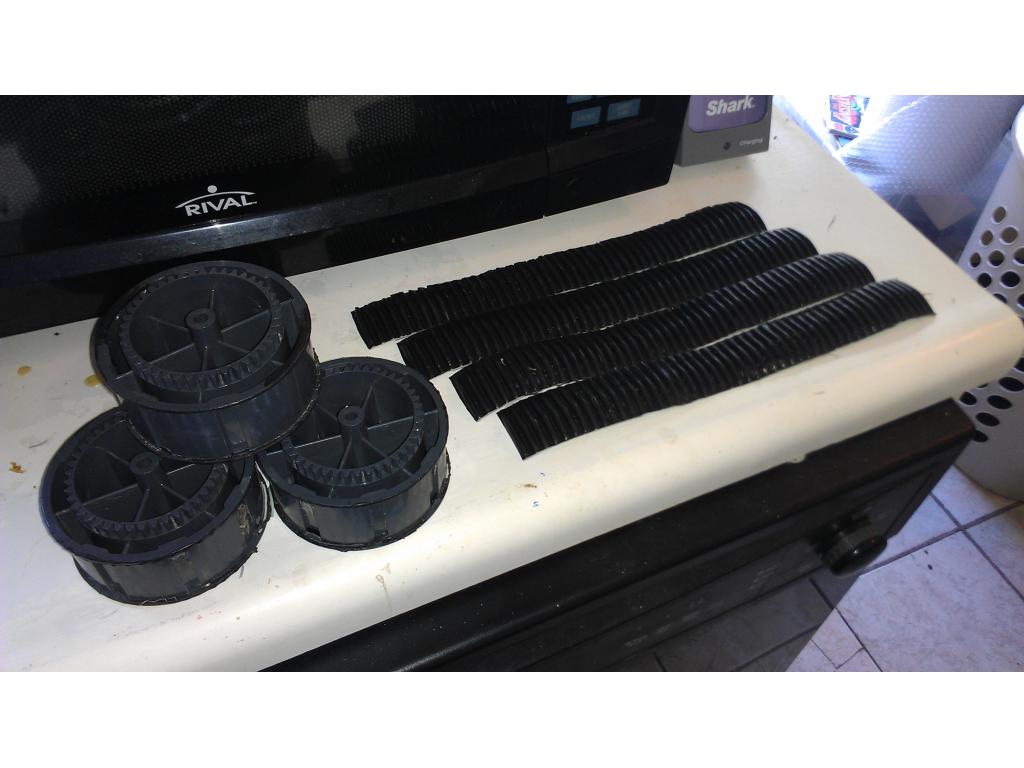
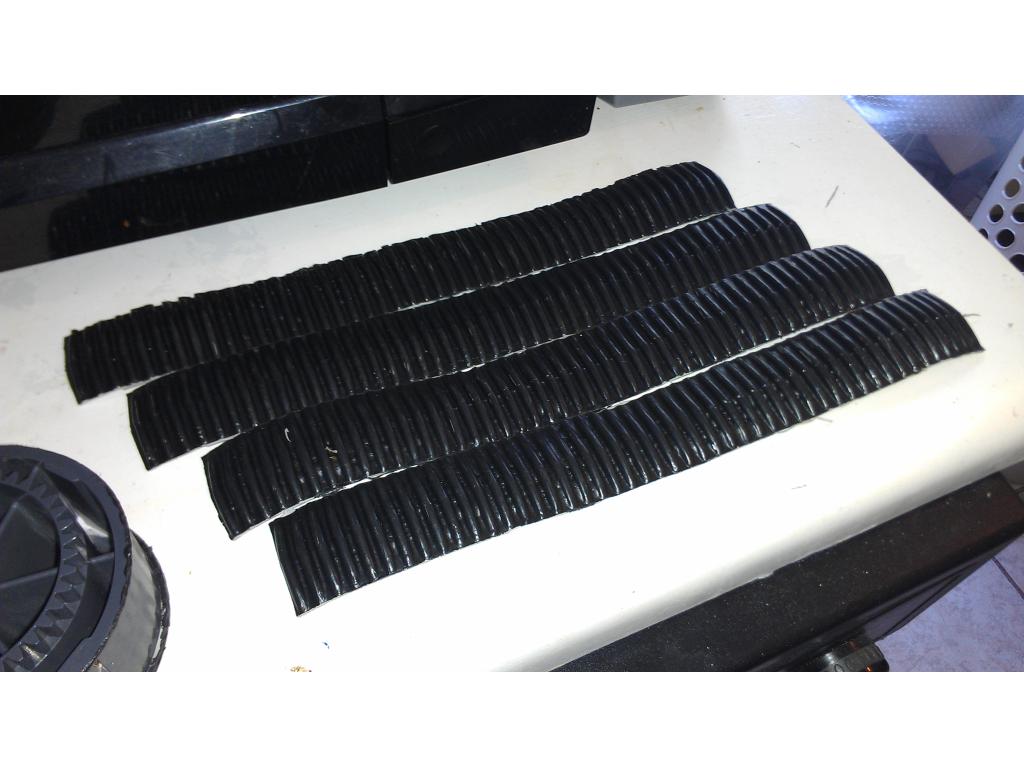
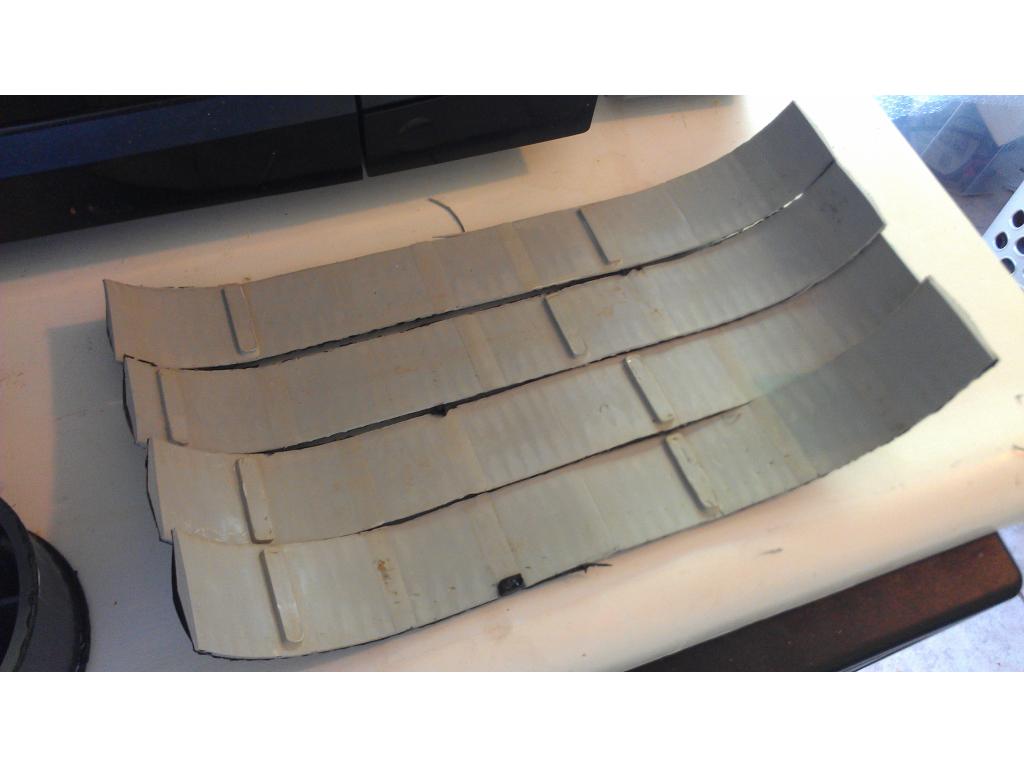
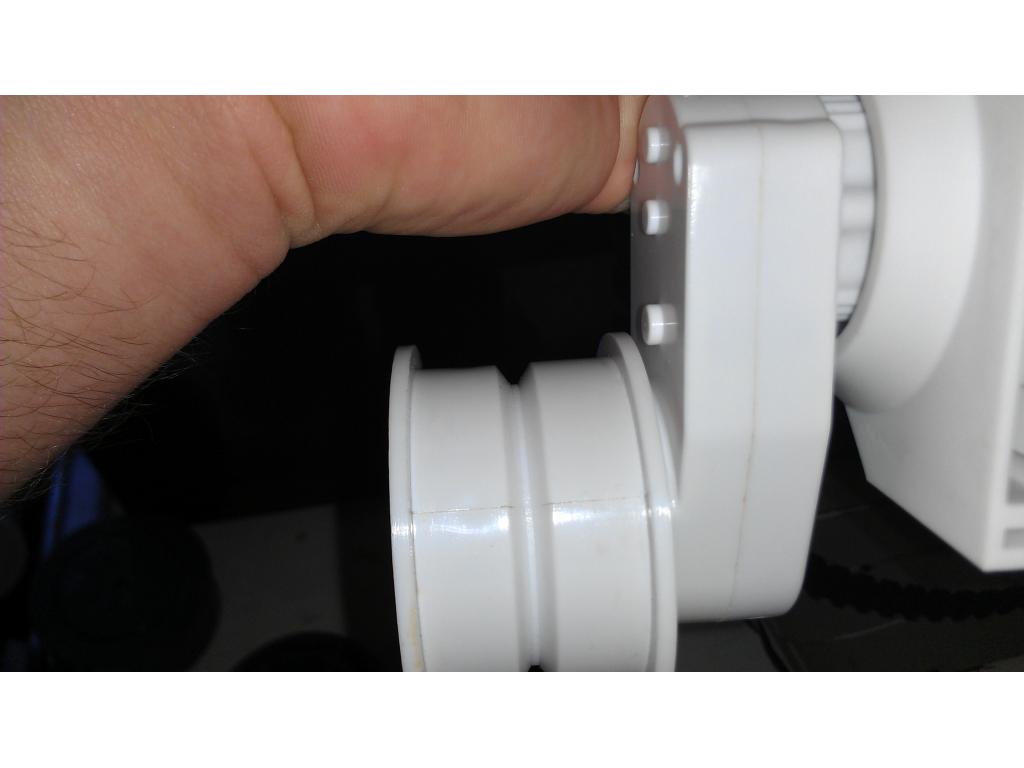
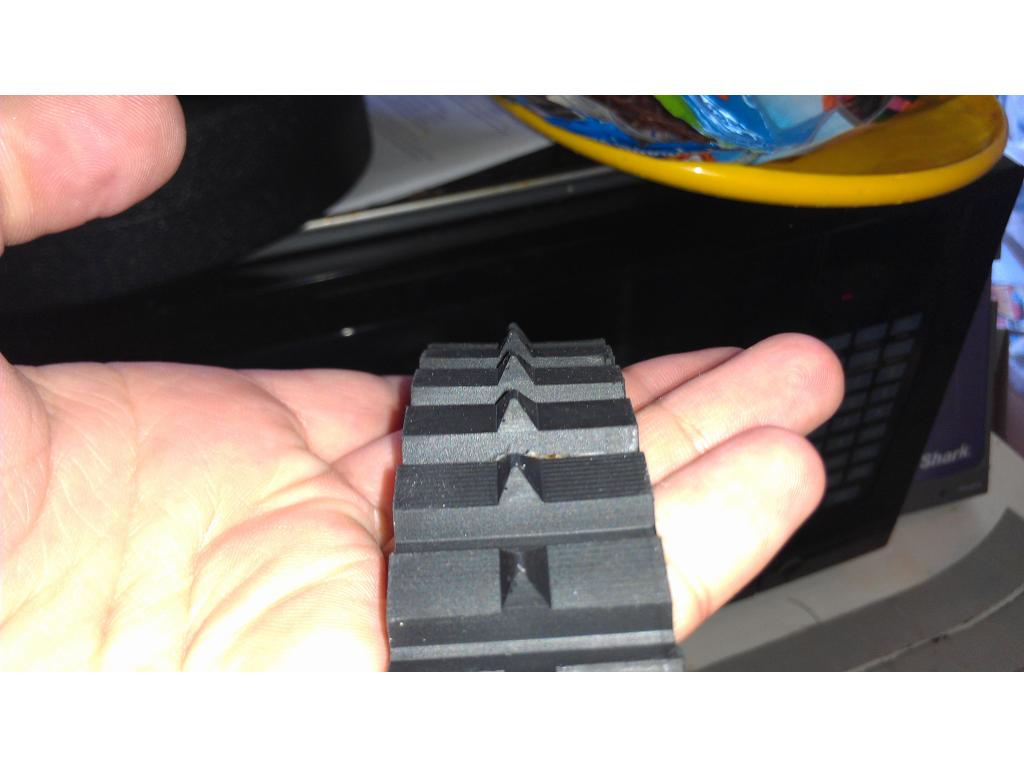
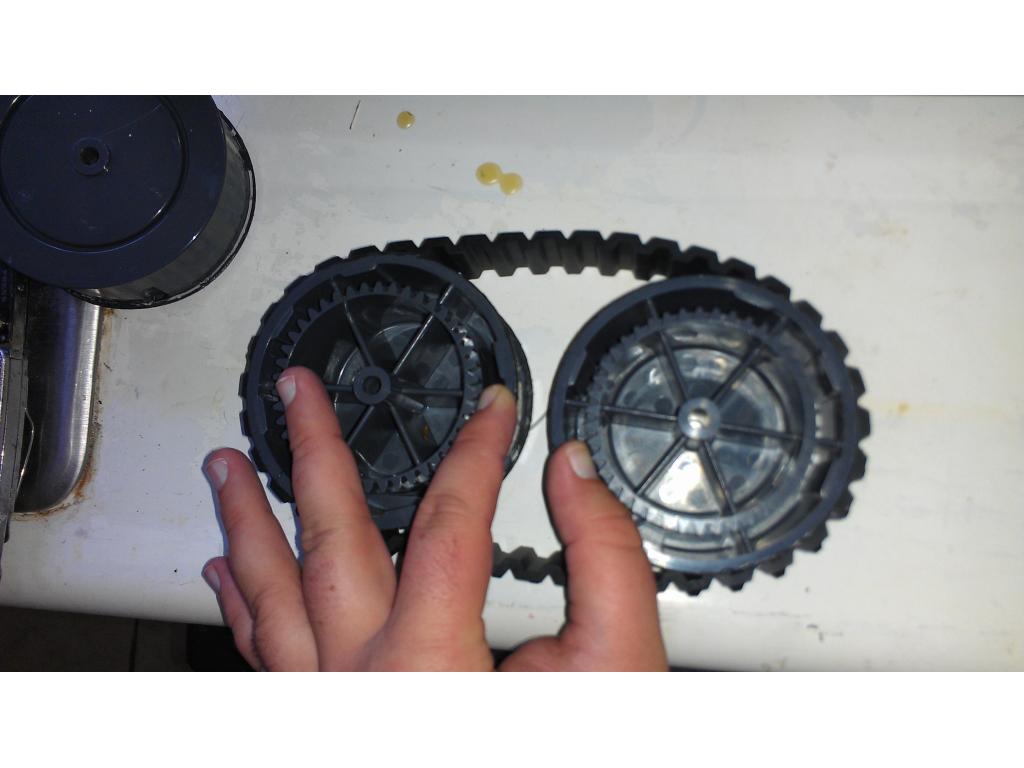
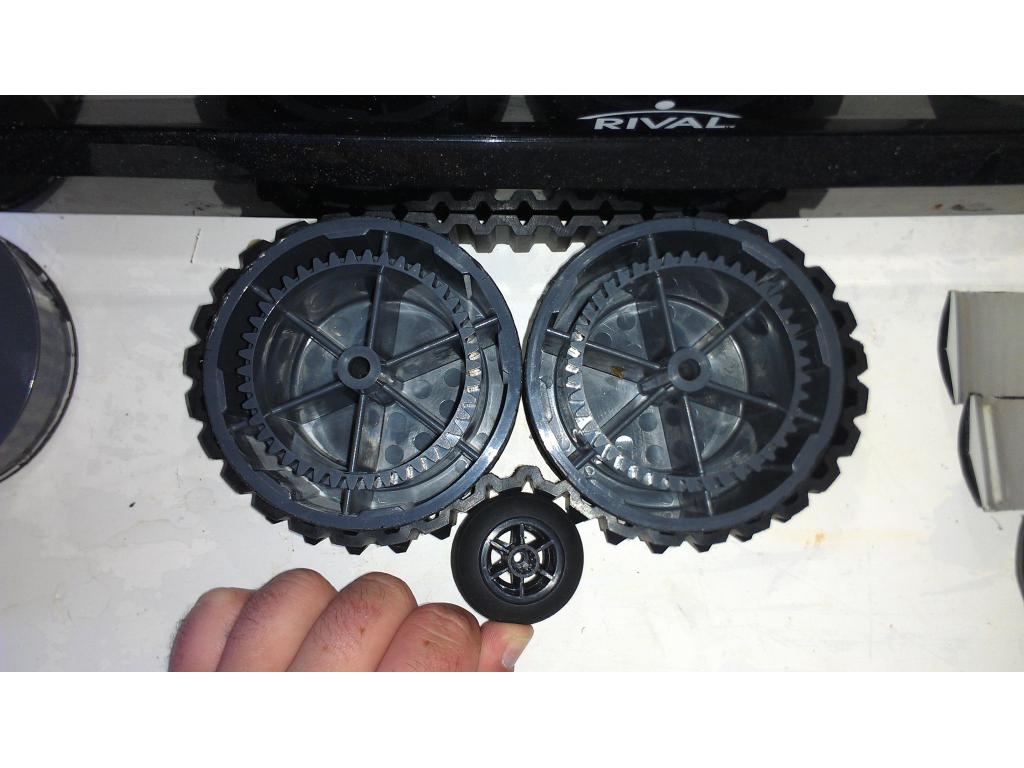
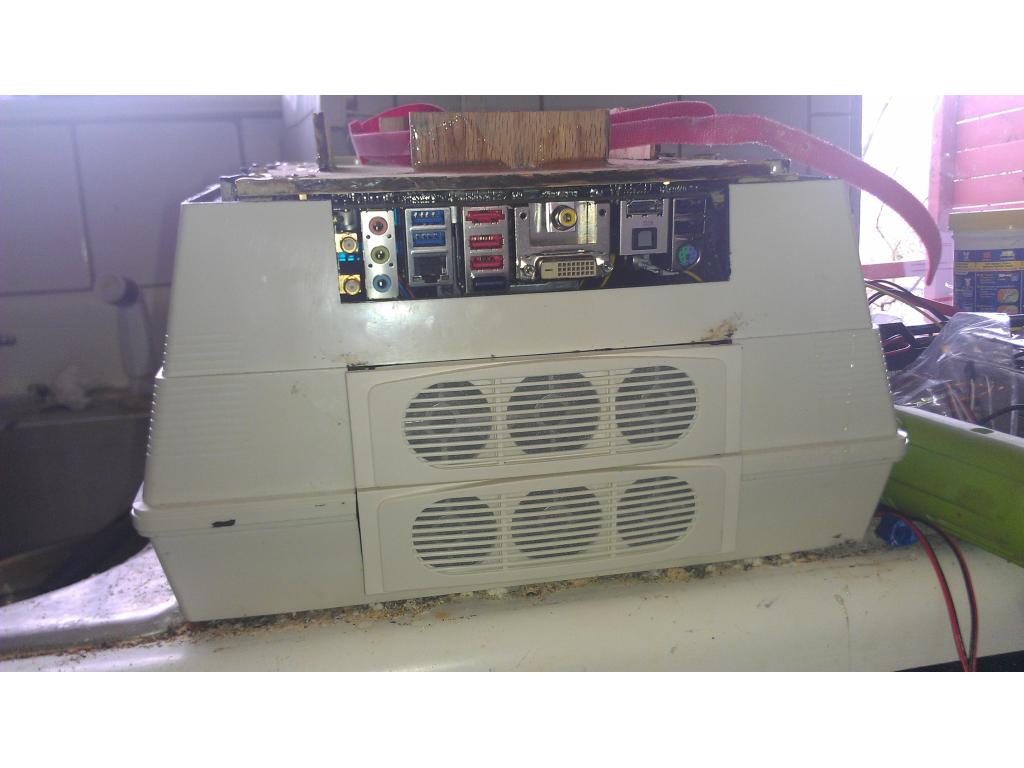
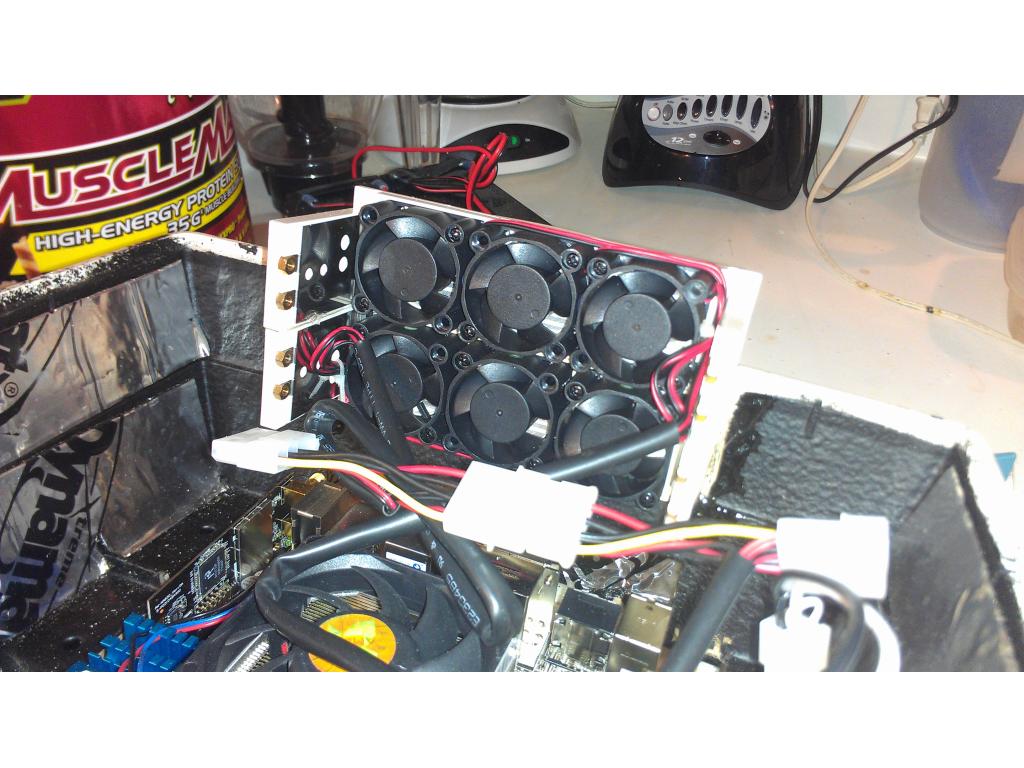
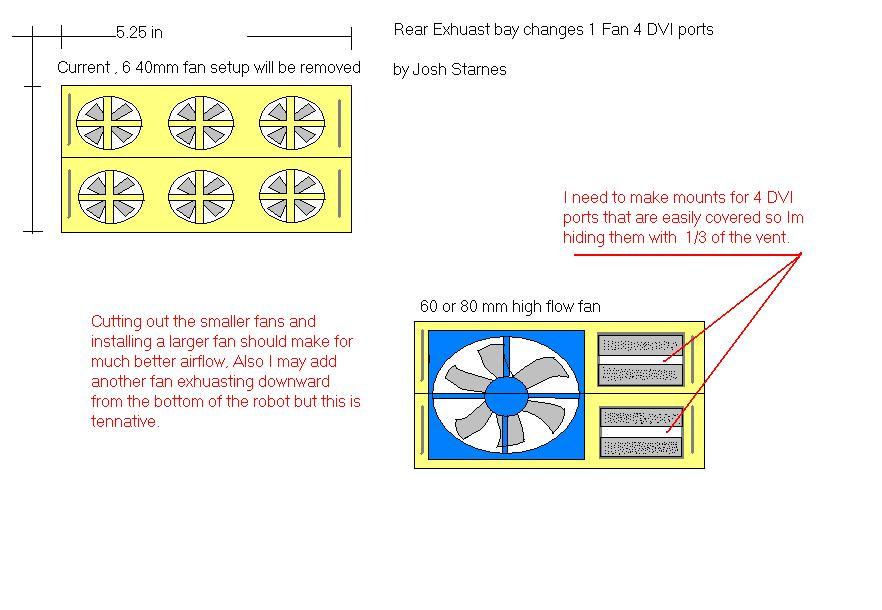
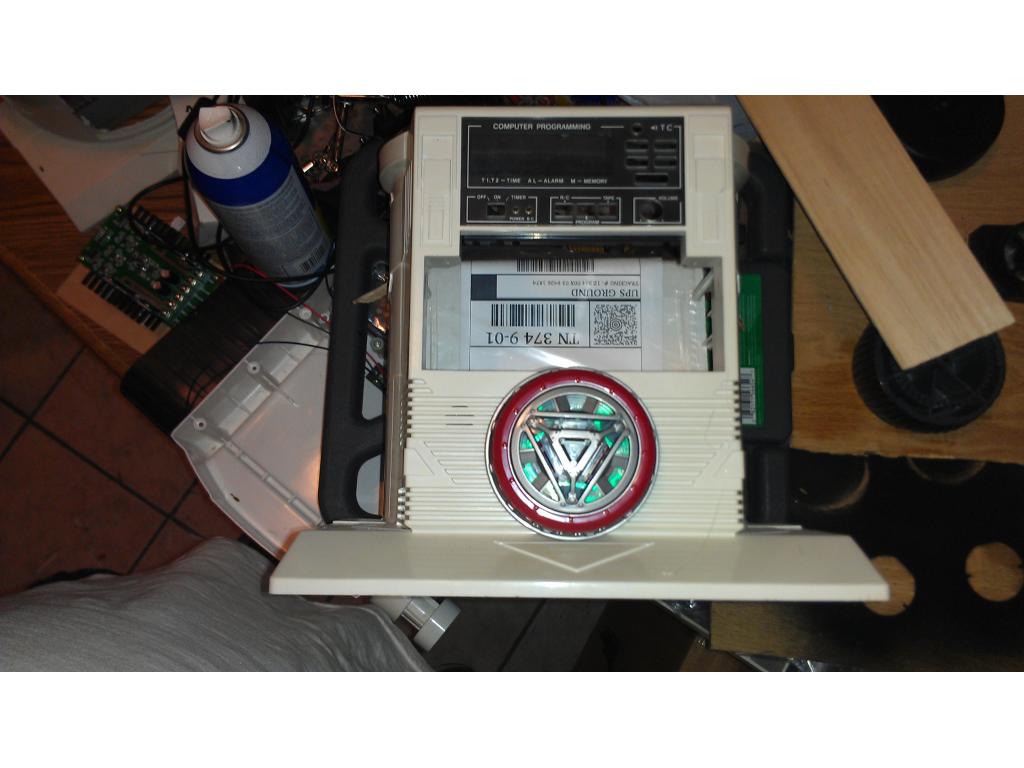
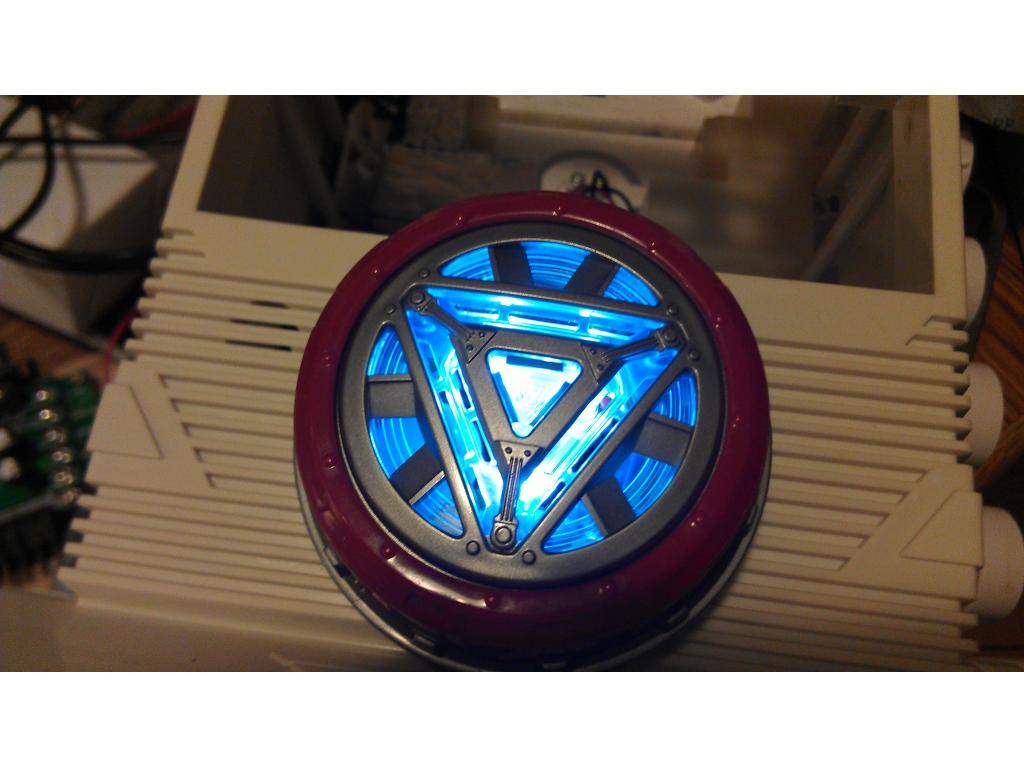
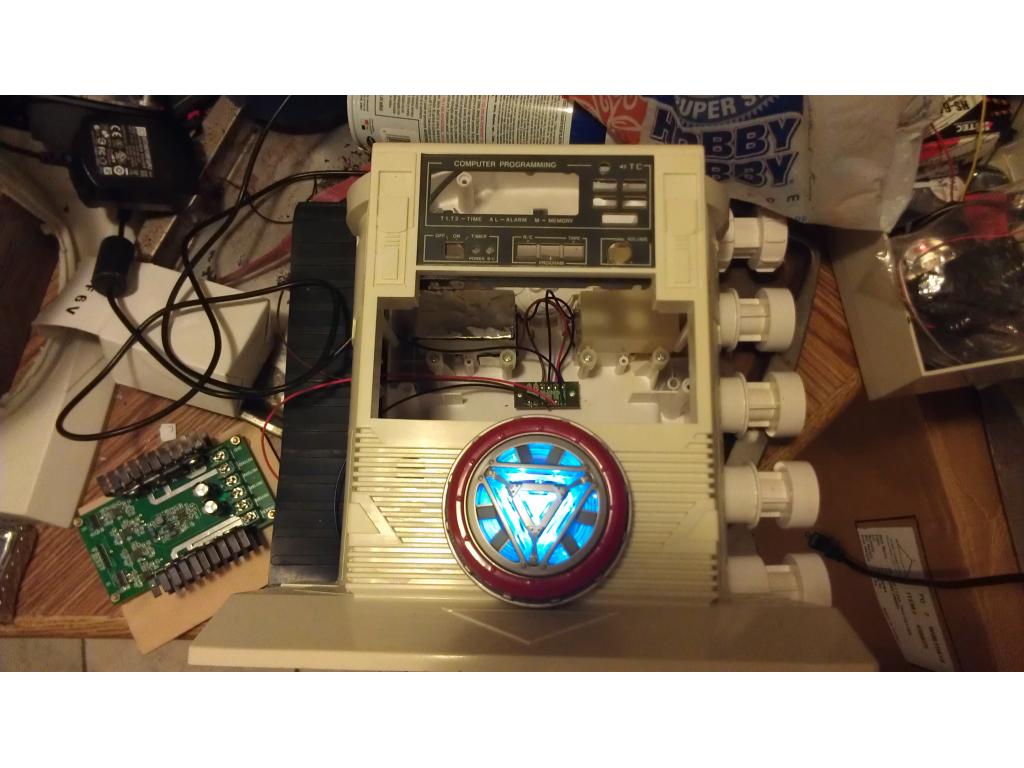
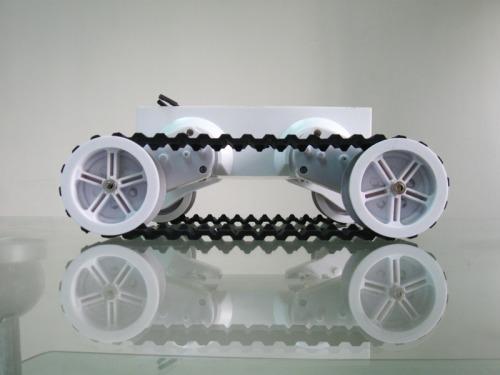
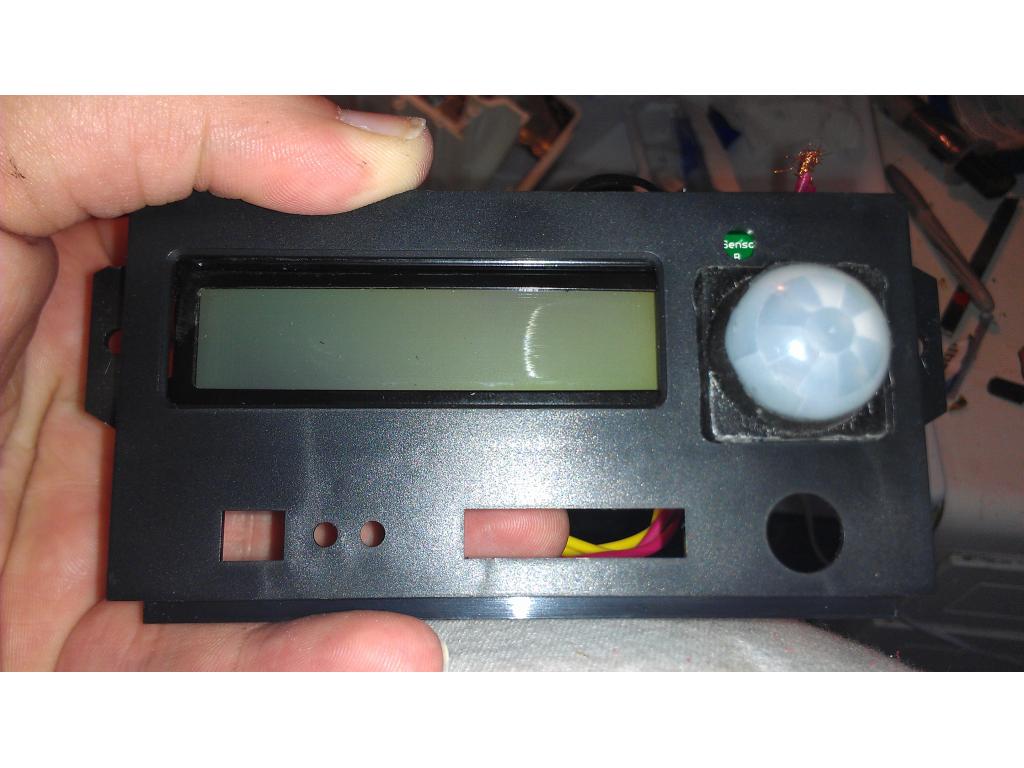
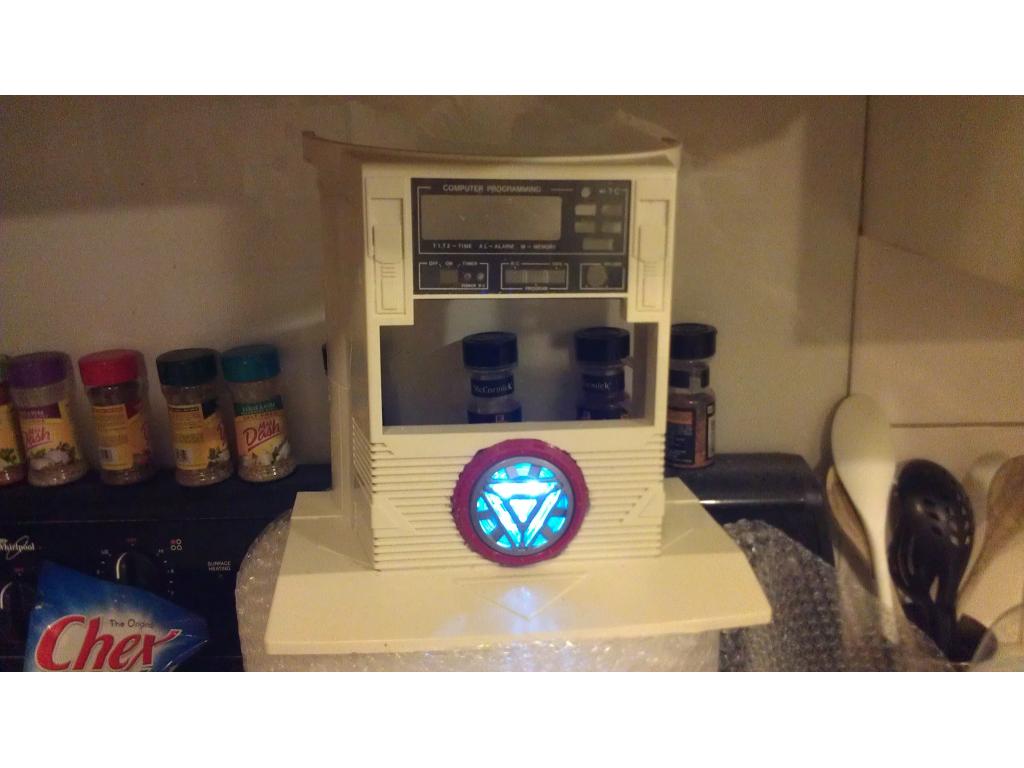
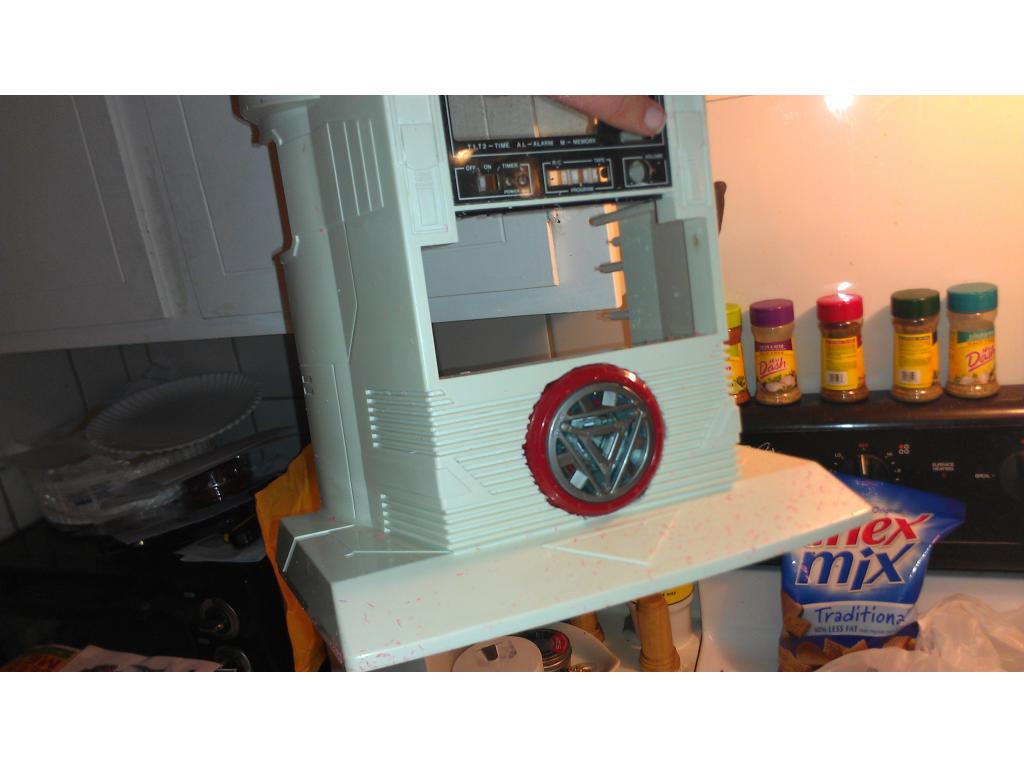
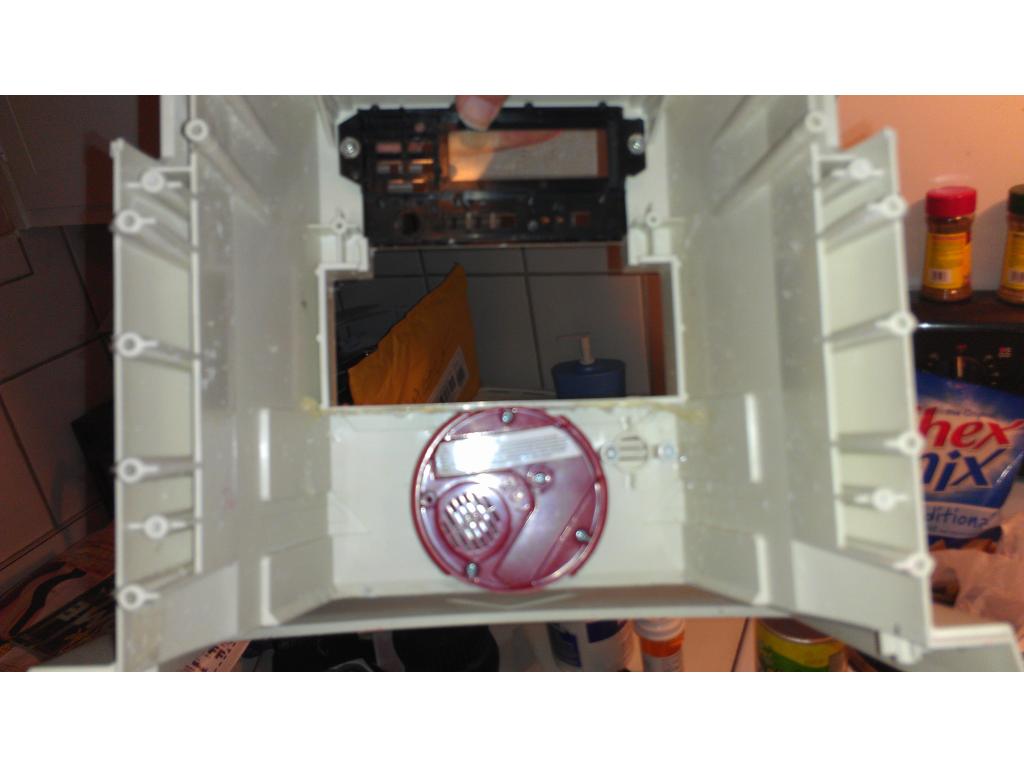
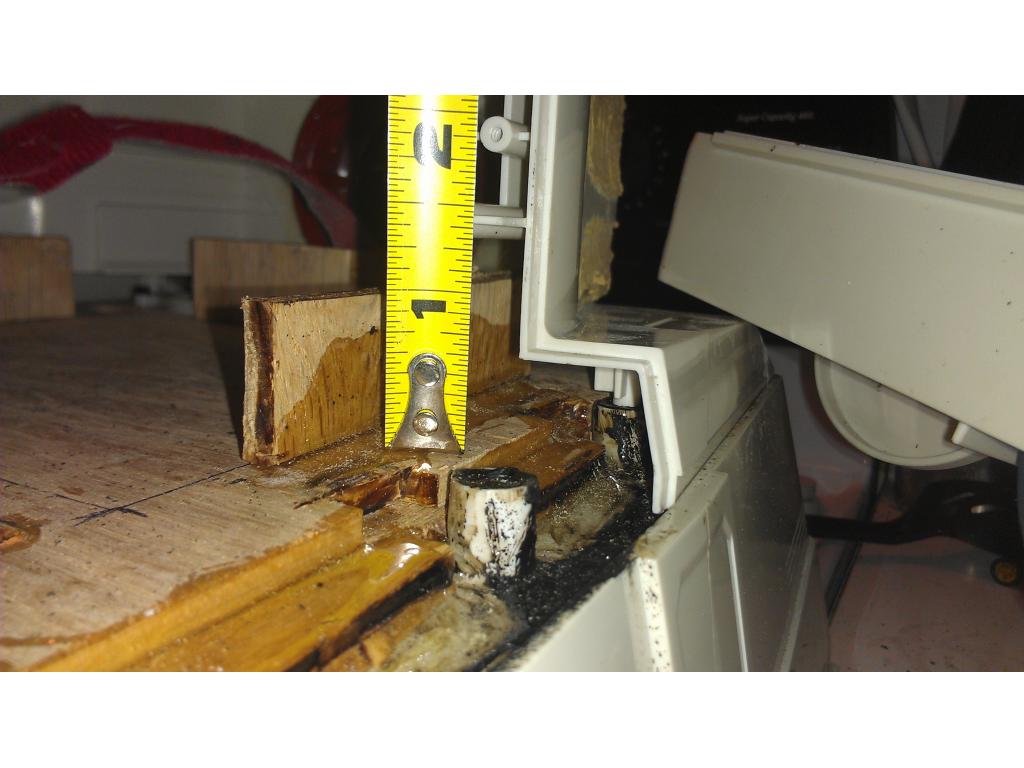
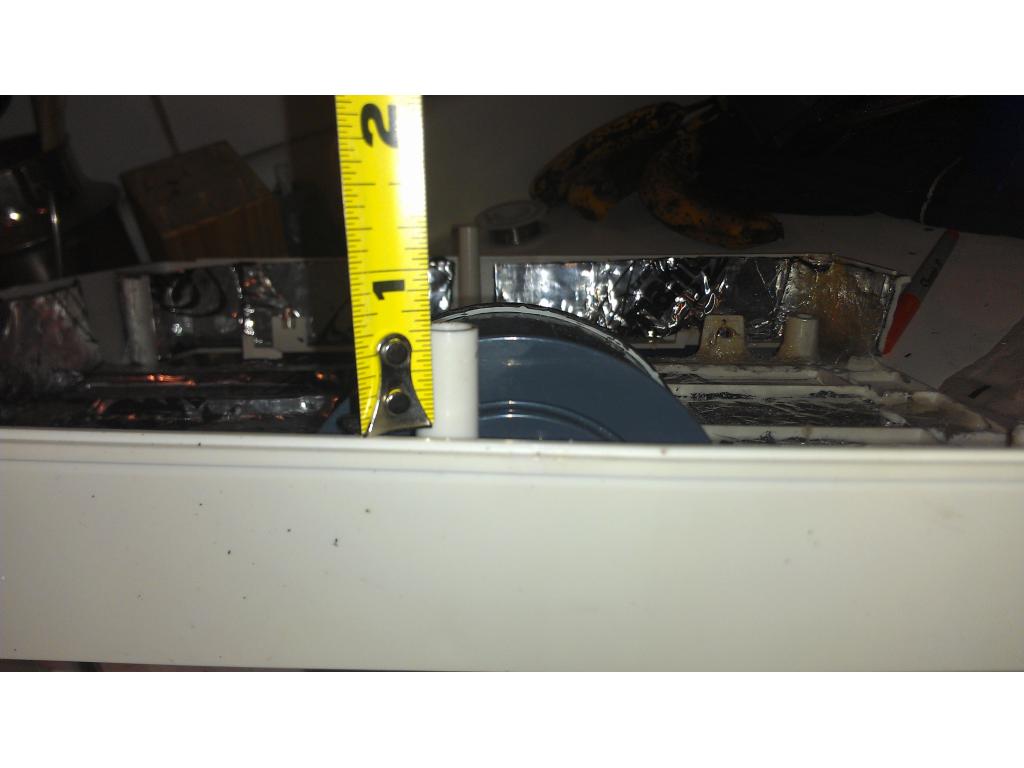
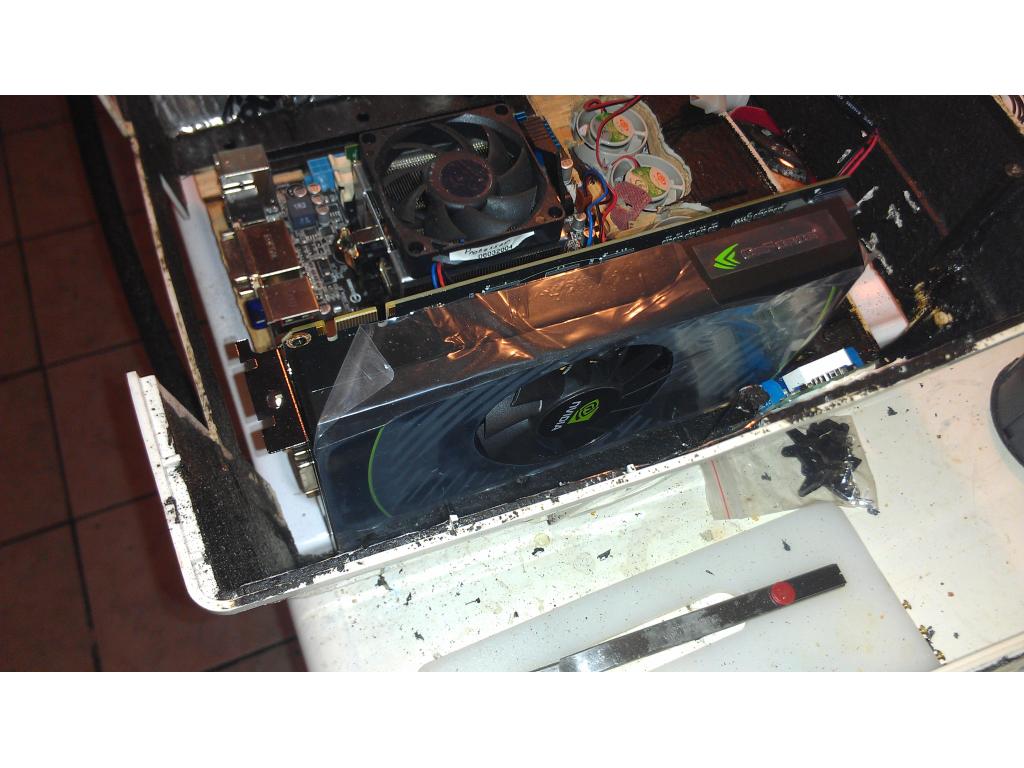
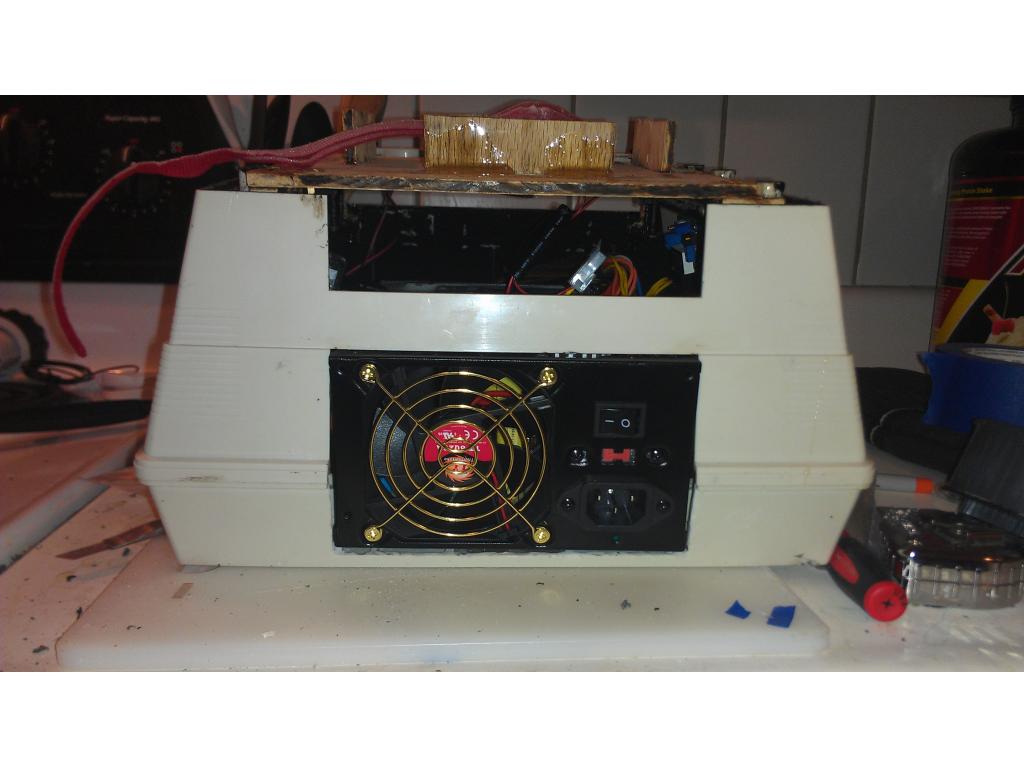
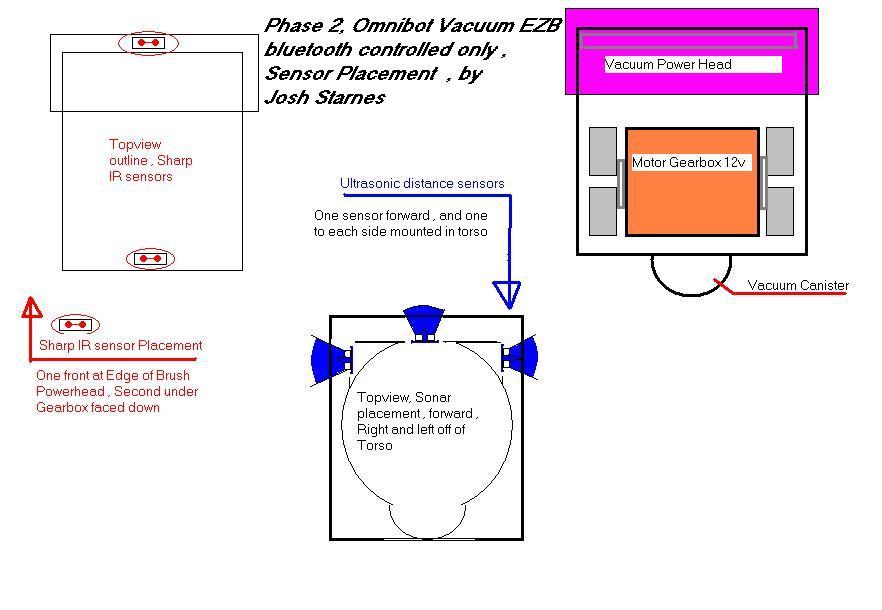
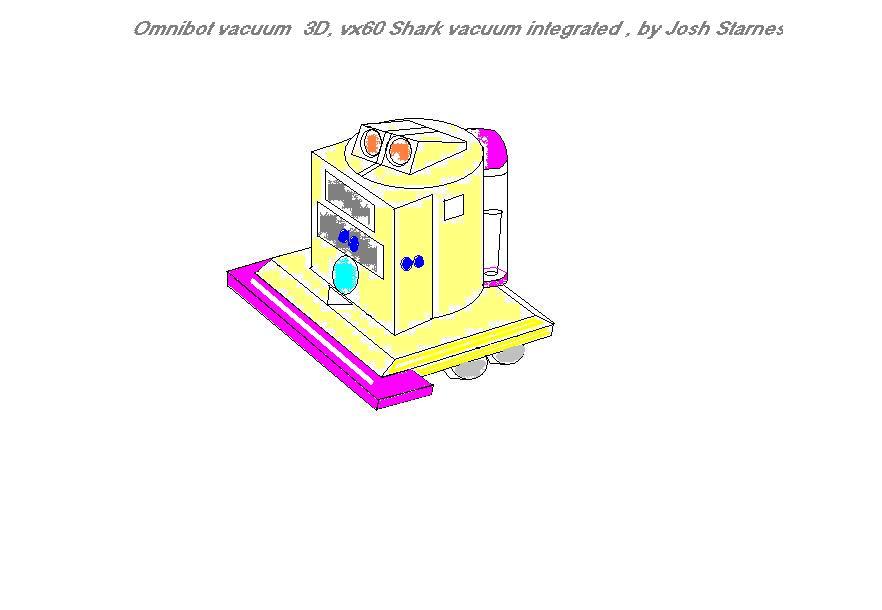
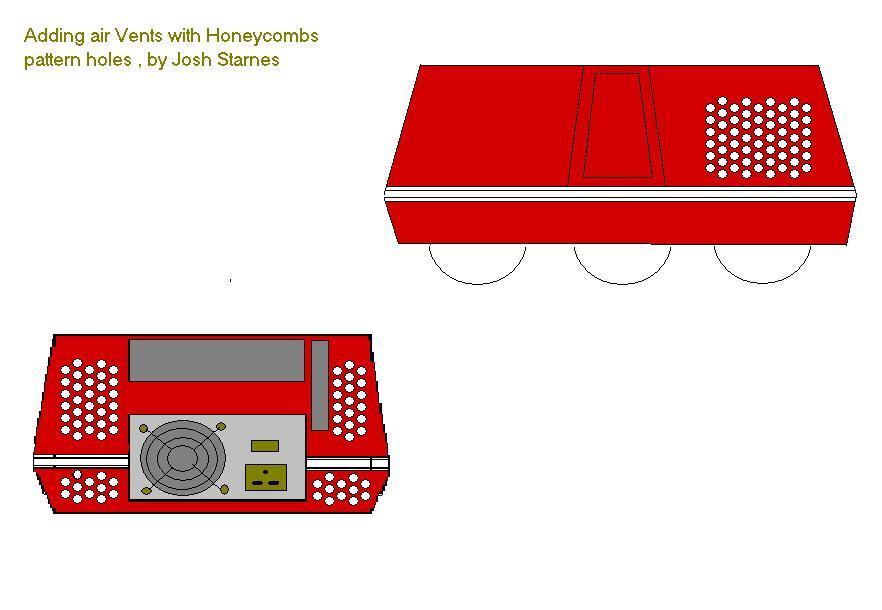
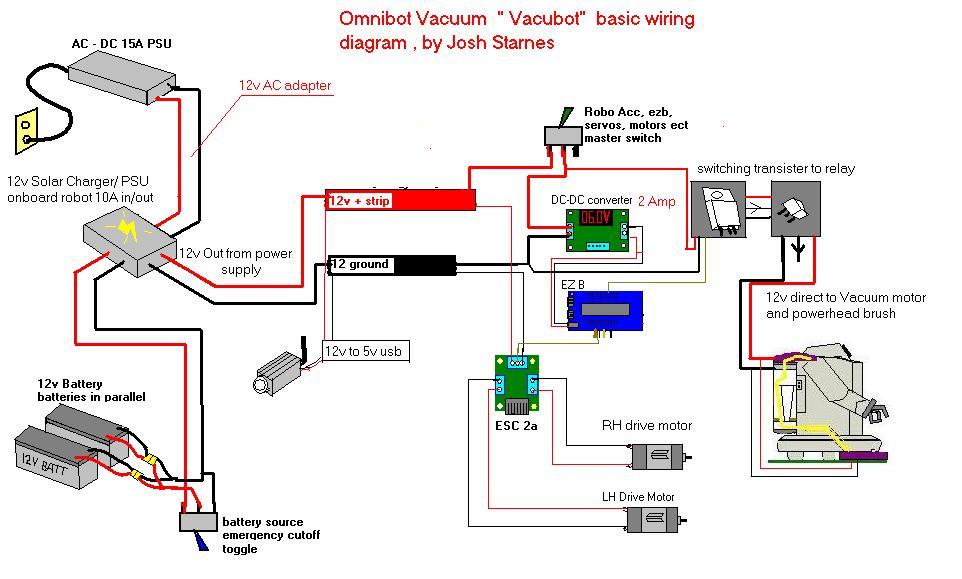
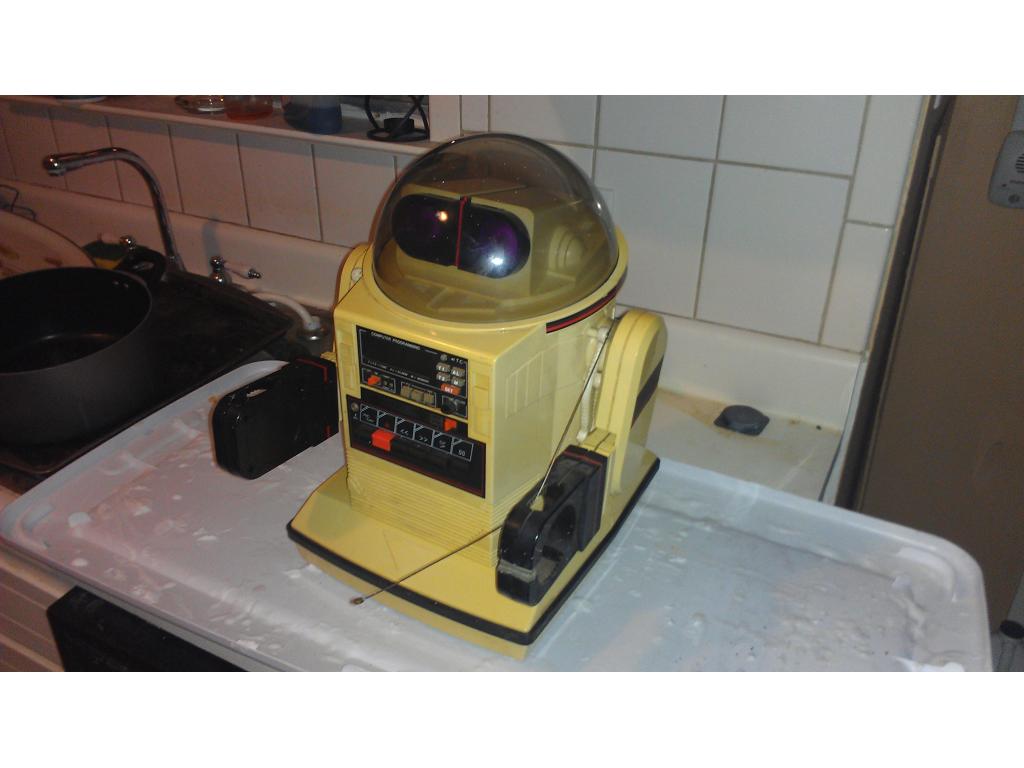
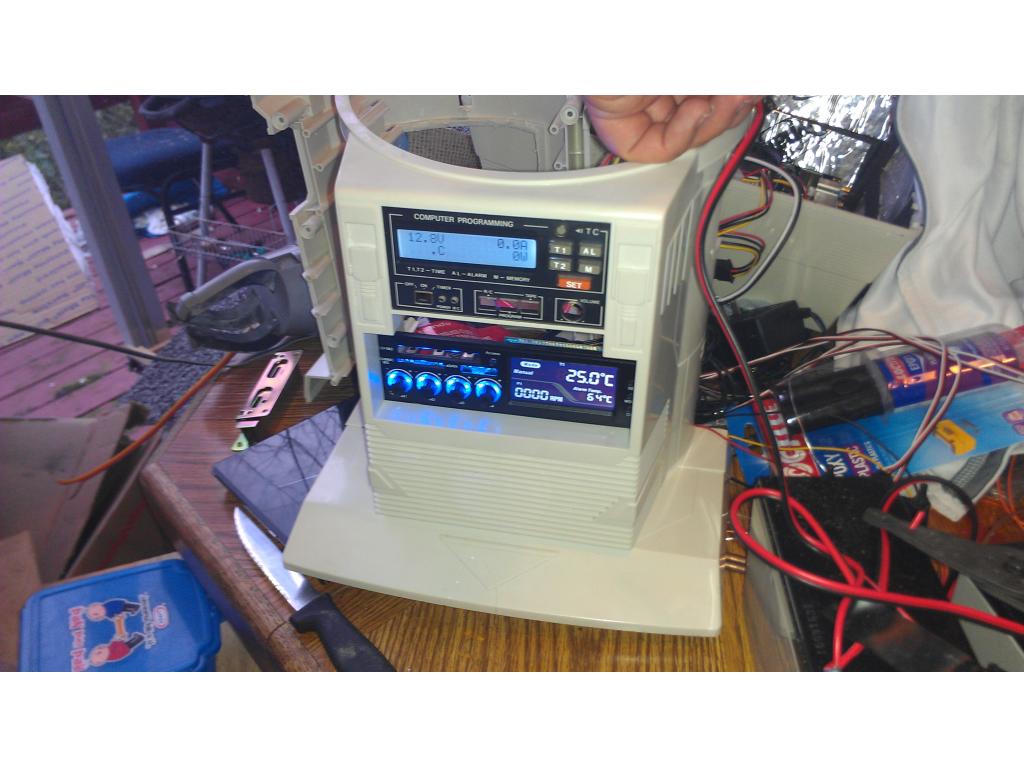
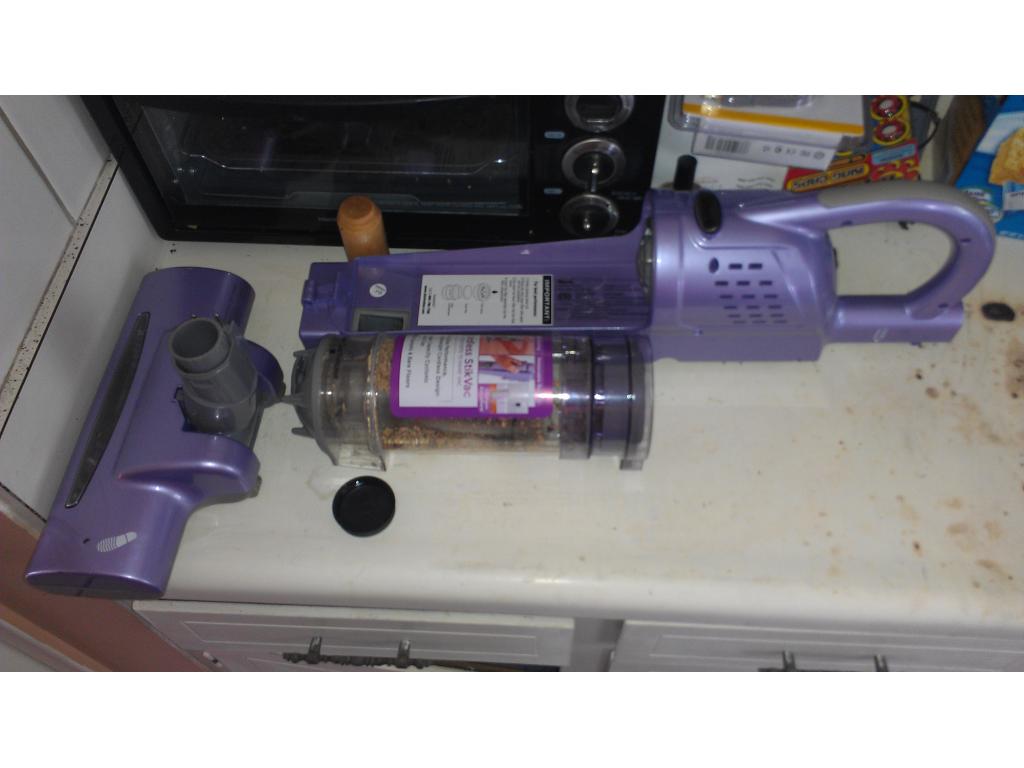
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.

By jstarne1
— Last update

Discover more robots
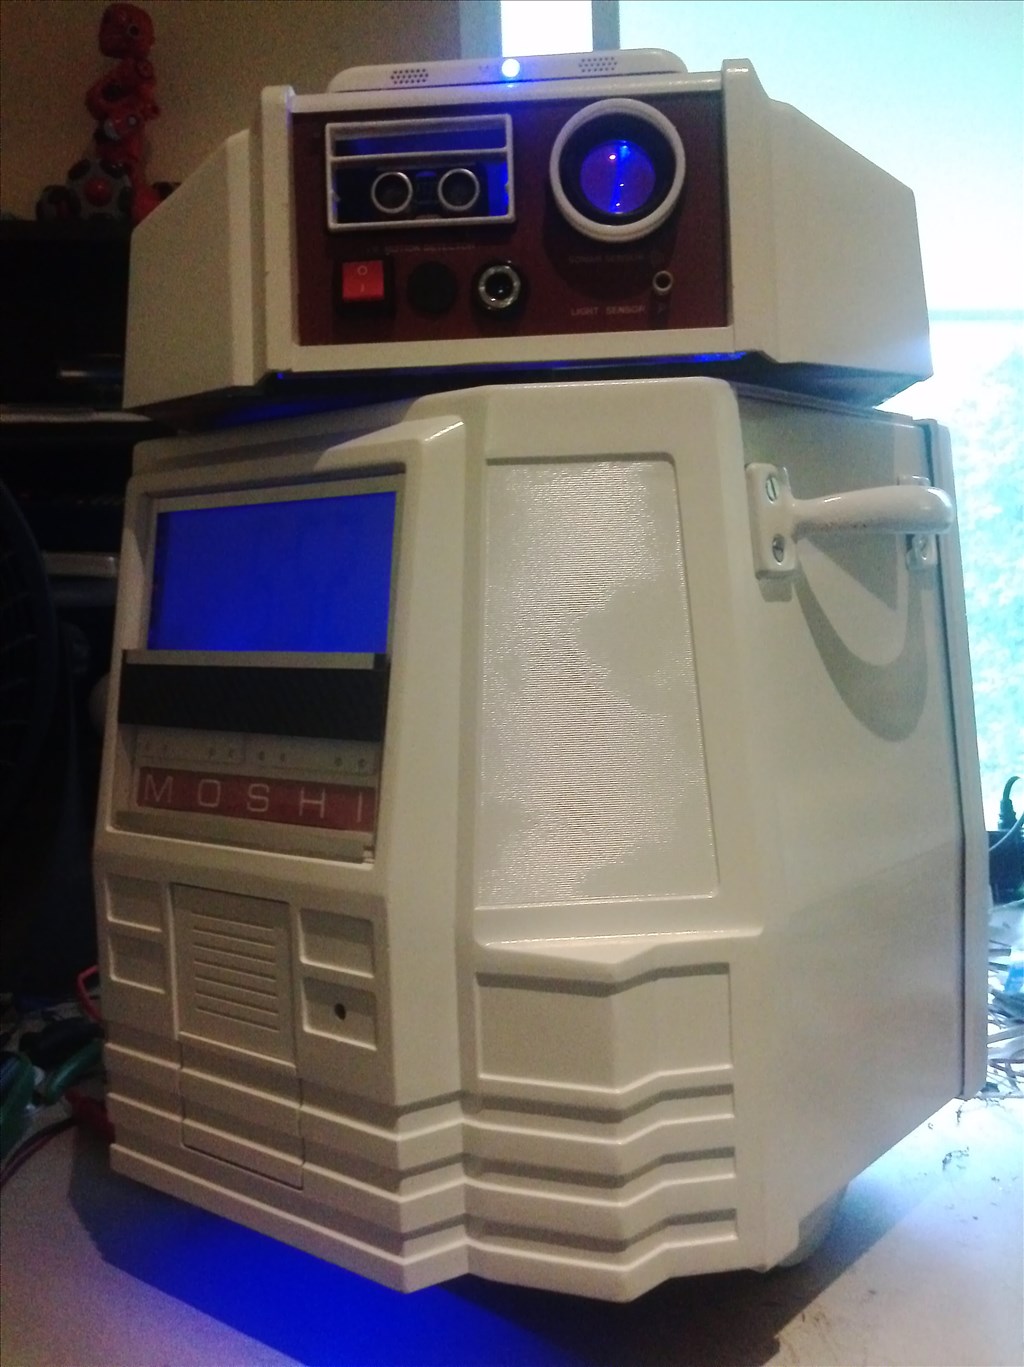
Rb550f's Moshi Is Alive
EZB 4 in MOSHI droid: aluminum internal frame, Sharper Image drive base with quiet 4-inch wheels, Bluetooth audio and...
Ezang's RGB Arduino, Python Code With ARC
Control Arduino RGB LEDs via Synthiam ARC serial monitor with Python code; ask a color and watch R G B light up.
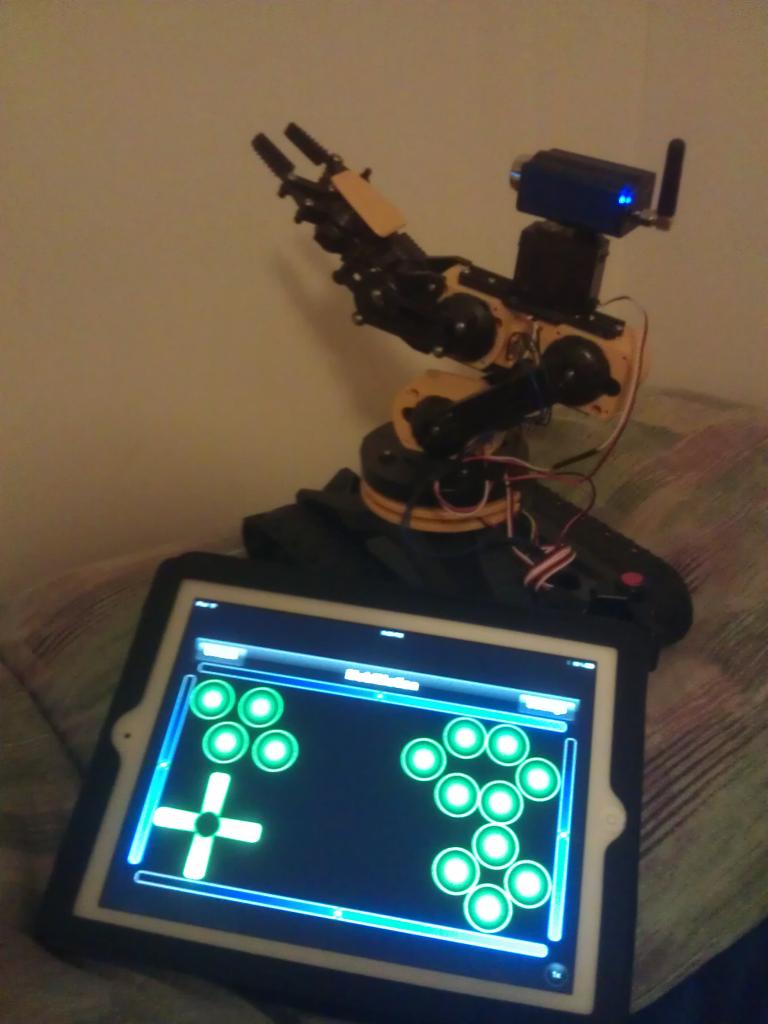
J's Robo Arm
Control a second robot arm from an iPad with the MobiMotion app-drive via accelerometer or joystick; photos show the...

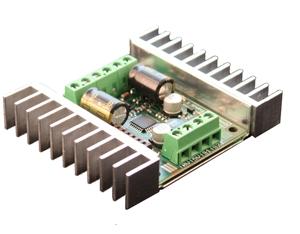
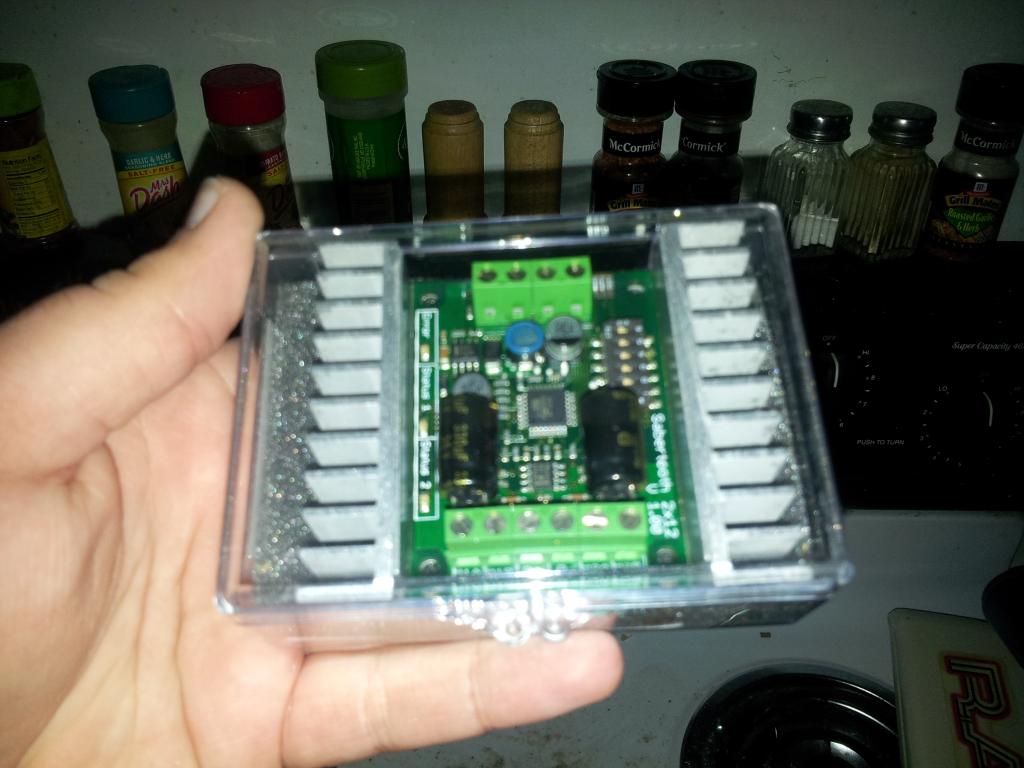
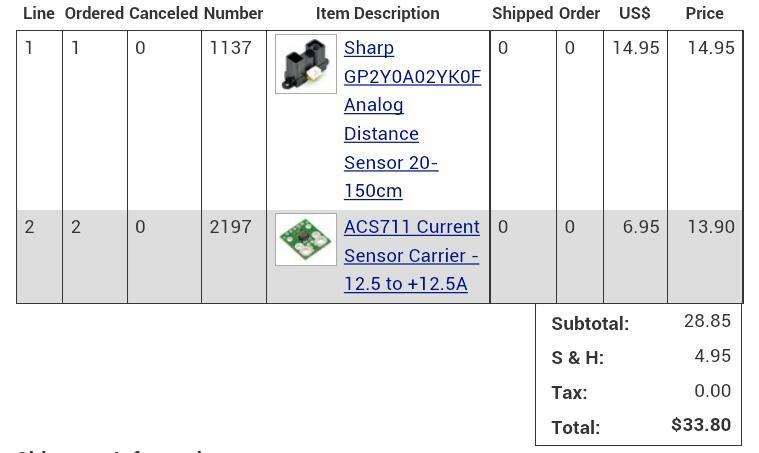
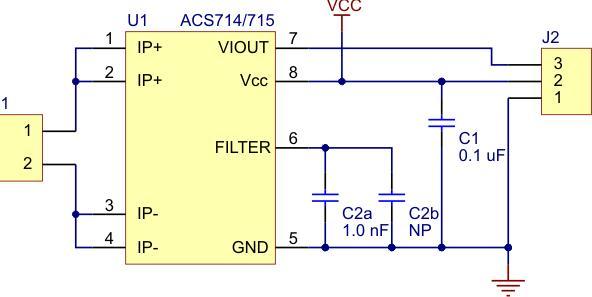
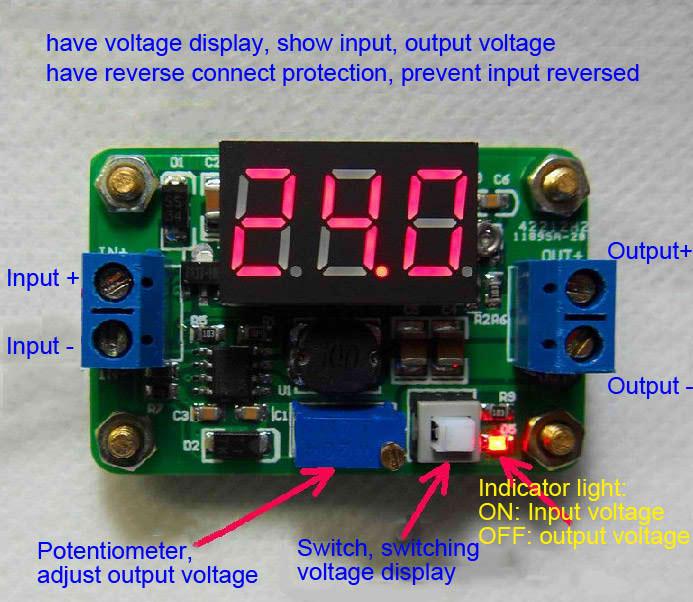
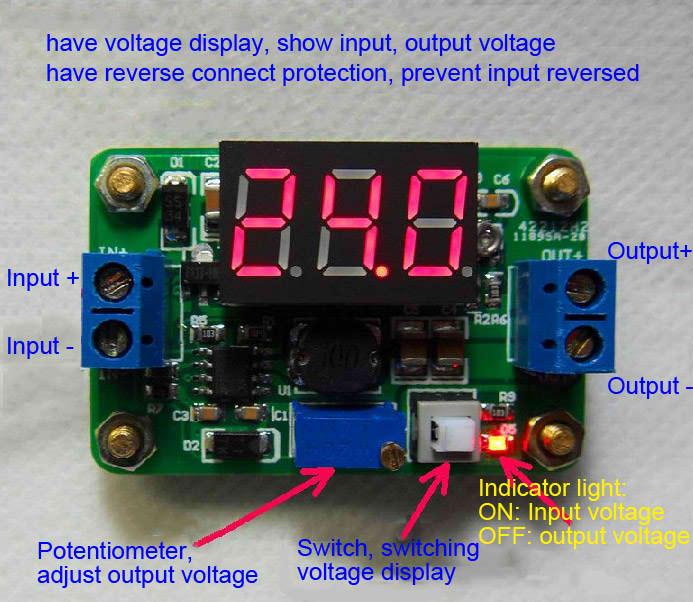
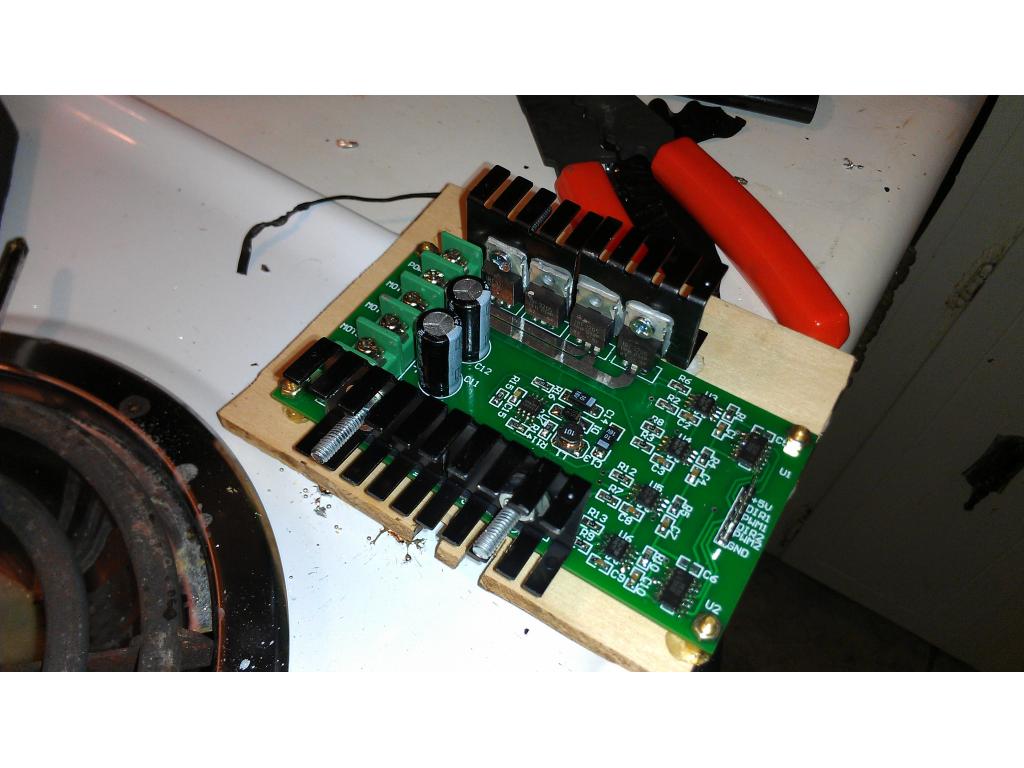
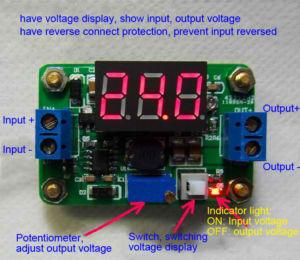
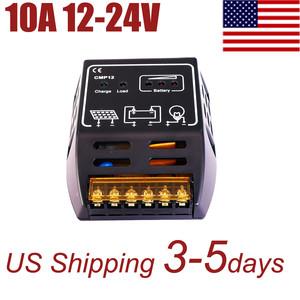
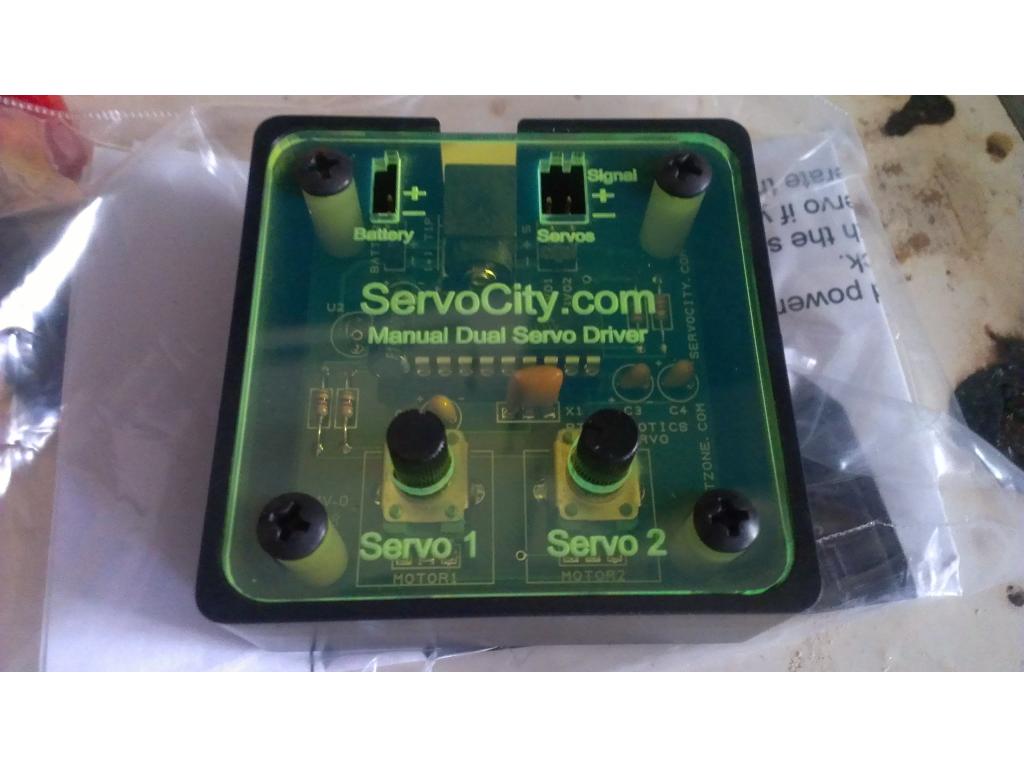
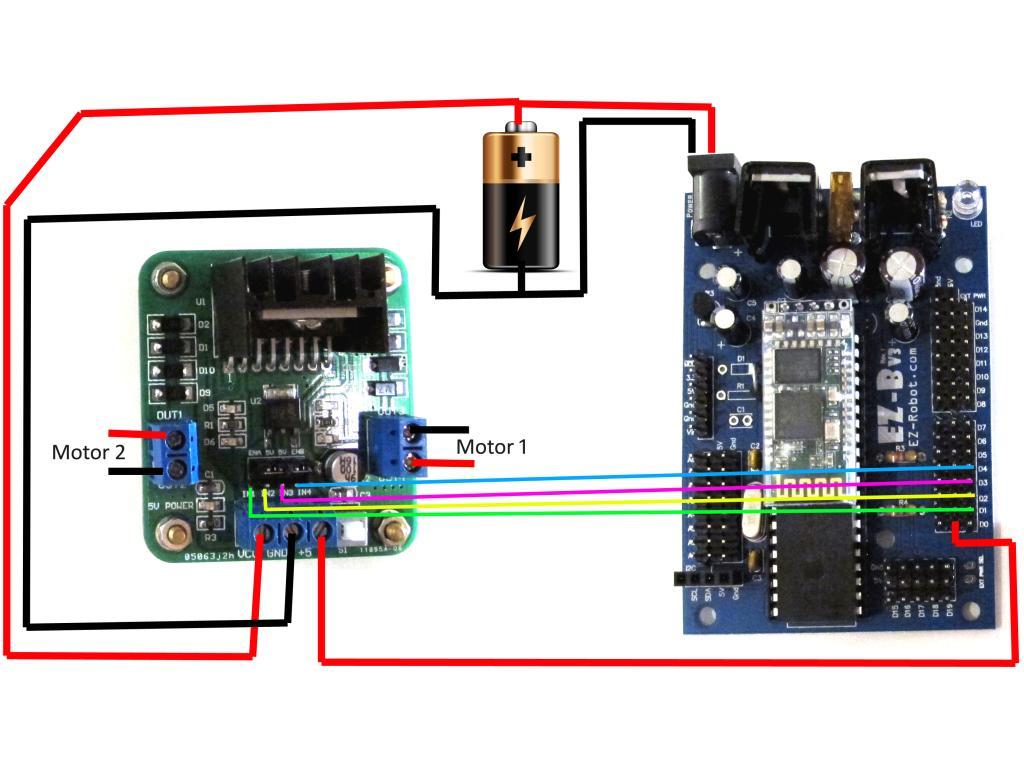
It appears to connect or disconnect the onboard 5v regulator. Which is unnecessary with the EZ-B providing said 5v.
check my reply on using that board ,it tells how to hook it up and EZB file example to use it since you and others wanted to know how to hook it up
on the switch i just tie the connects togetherm,its not really needed even if the switch is good ,just incase when using the board the switch doesnt pop up from vibration
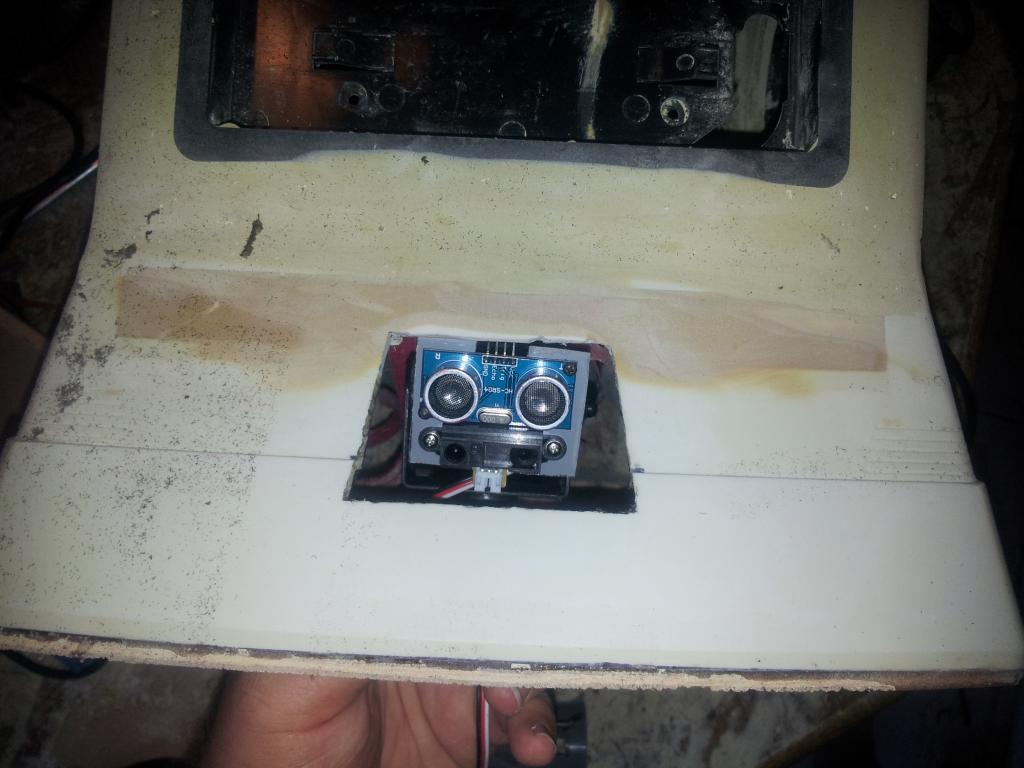
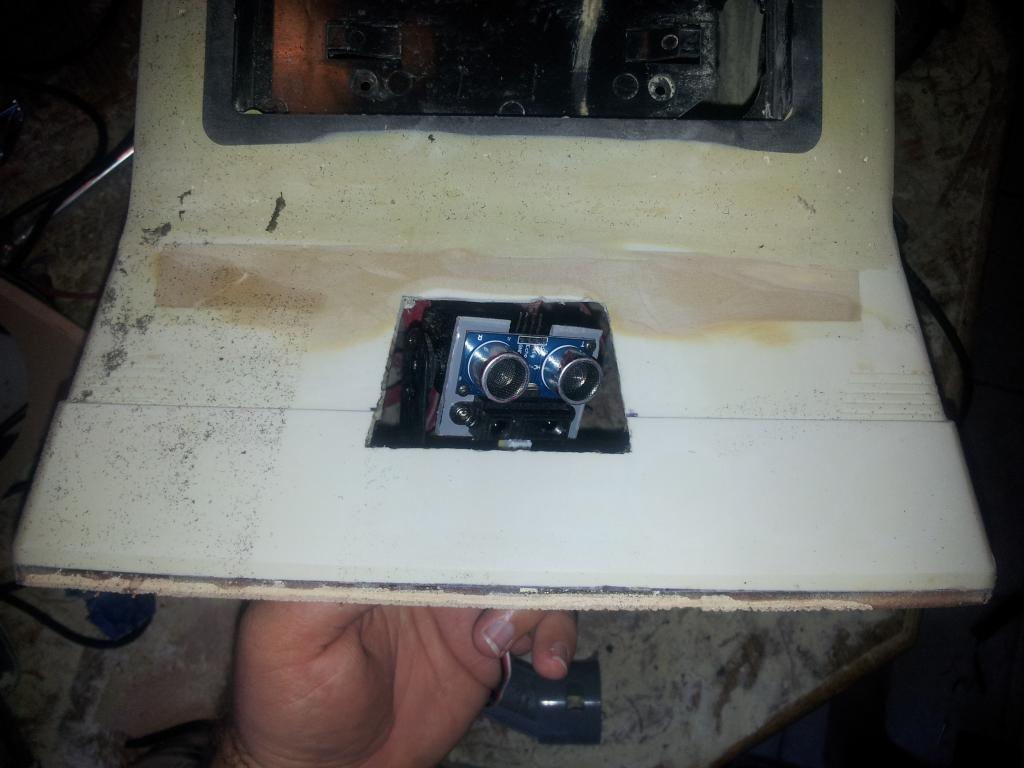
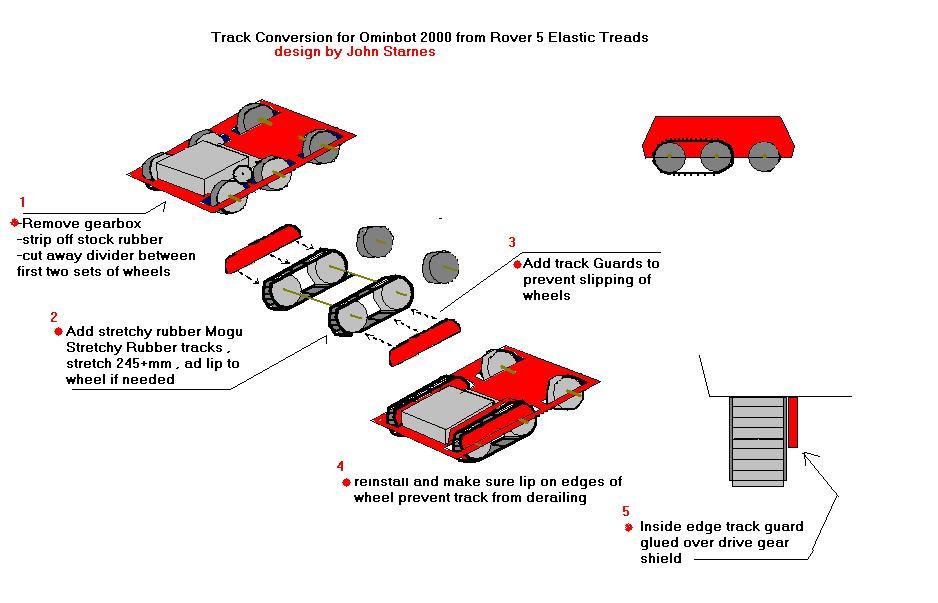
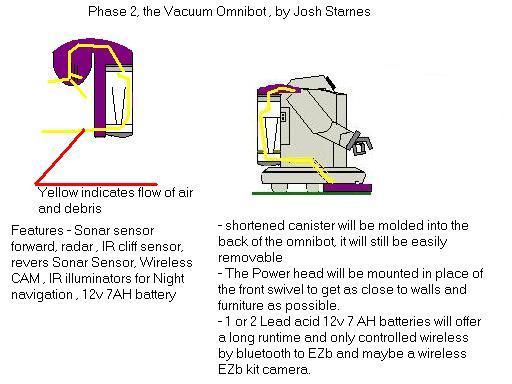
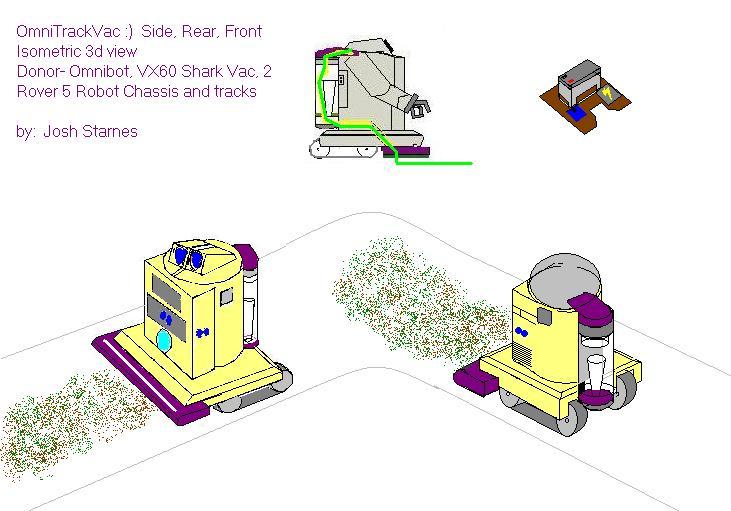
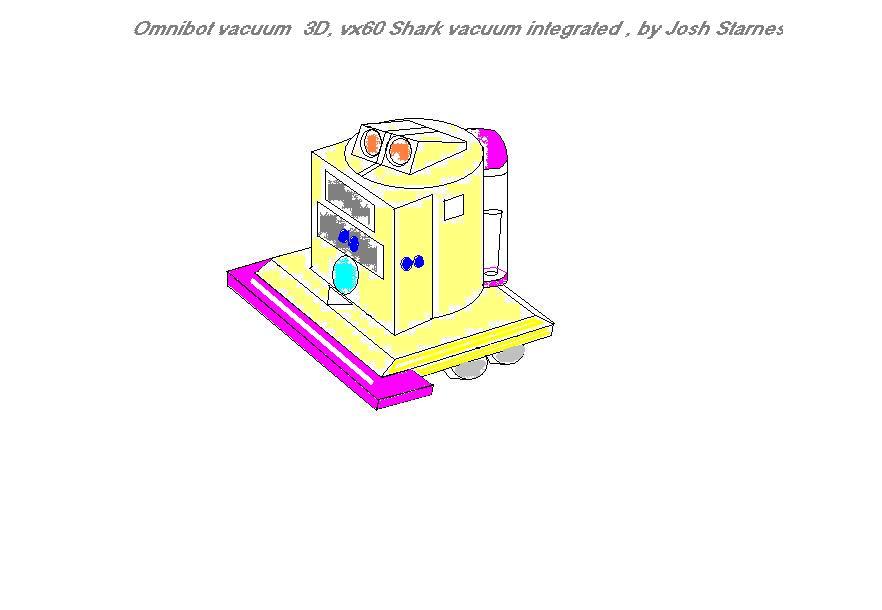
Tiny update , my vision of the omnitrackvac. Lol
Cool!
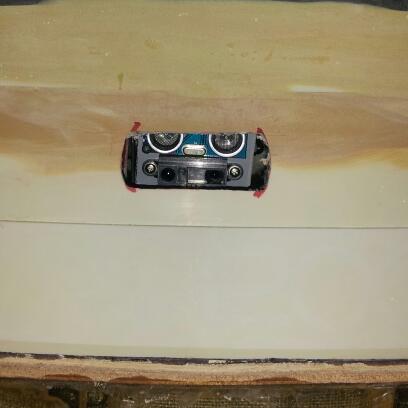
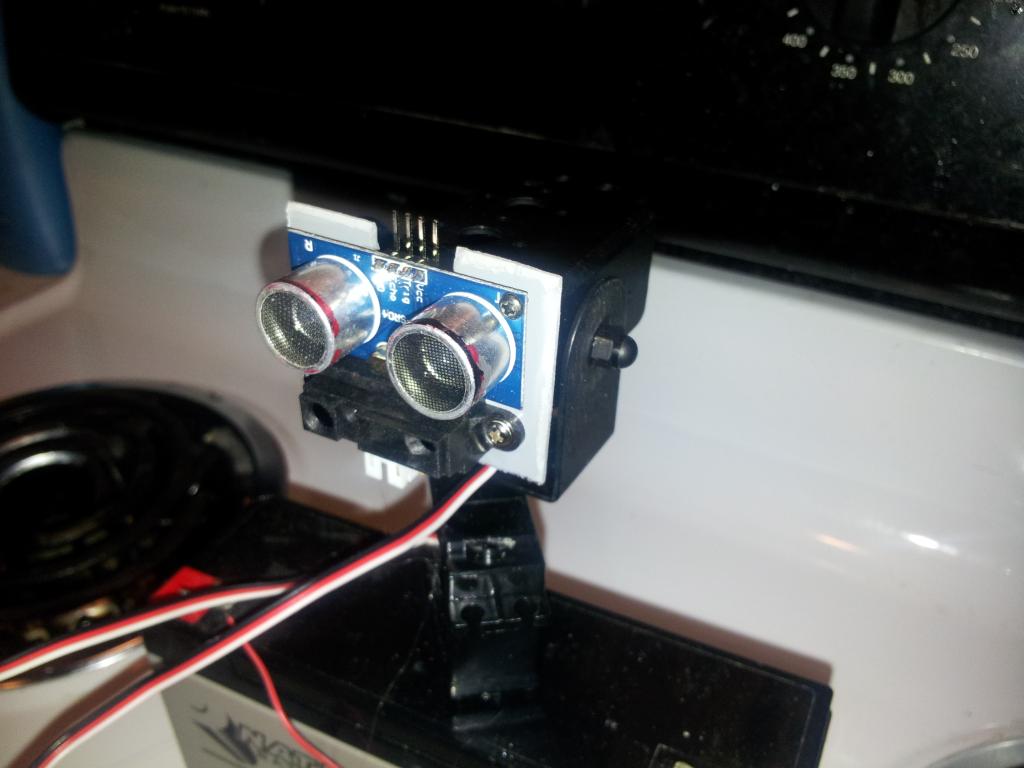
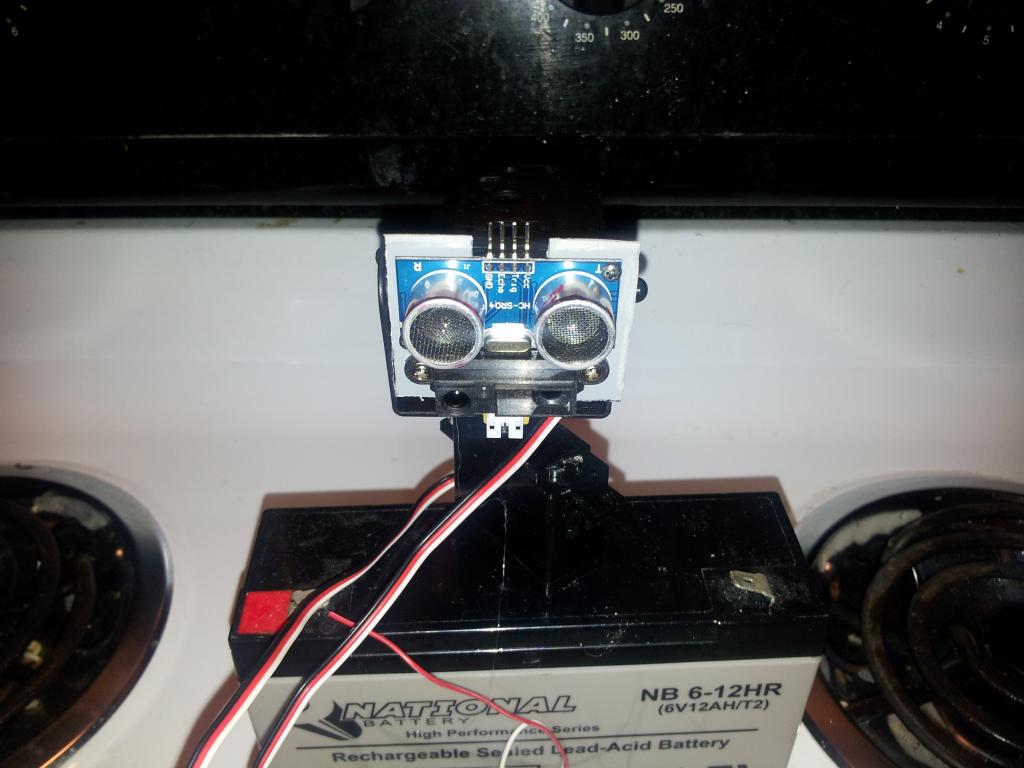
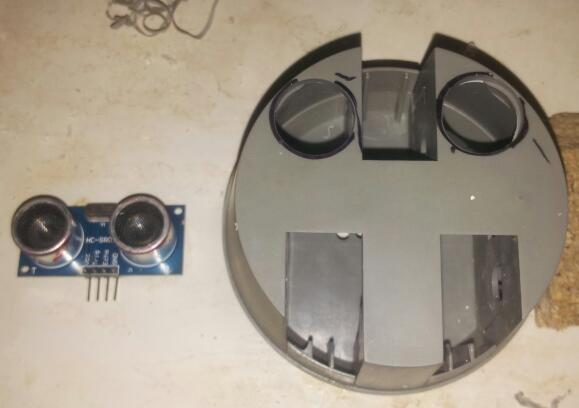
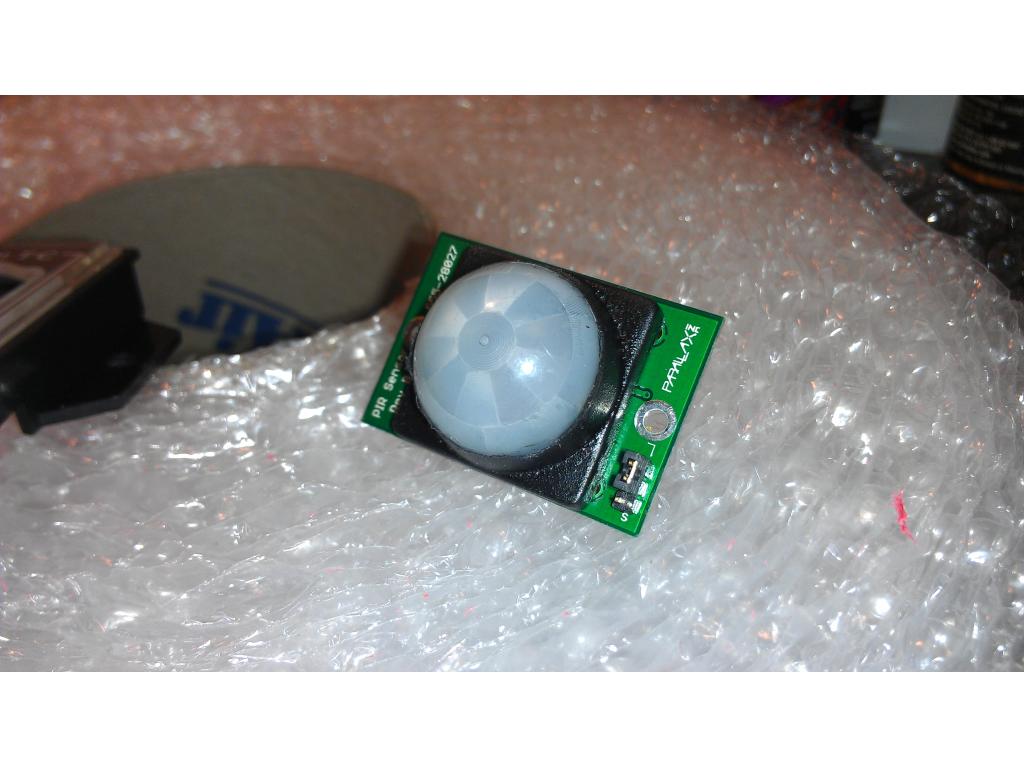
Yes Brett , I could definitely use that sonar sensor and micro servo. I'll email my address.
good deal, I'll send them to you as soon as I get it.
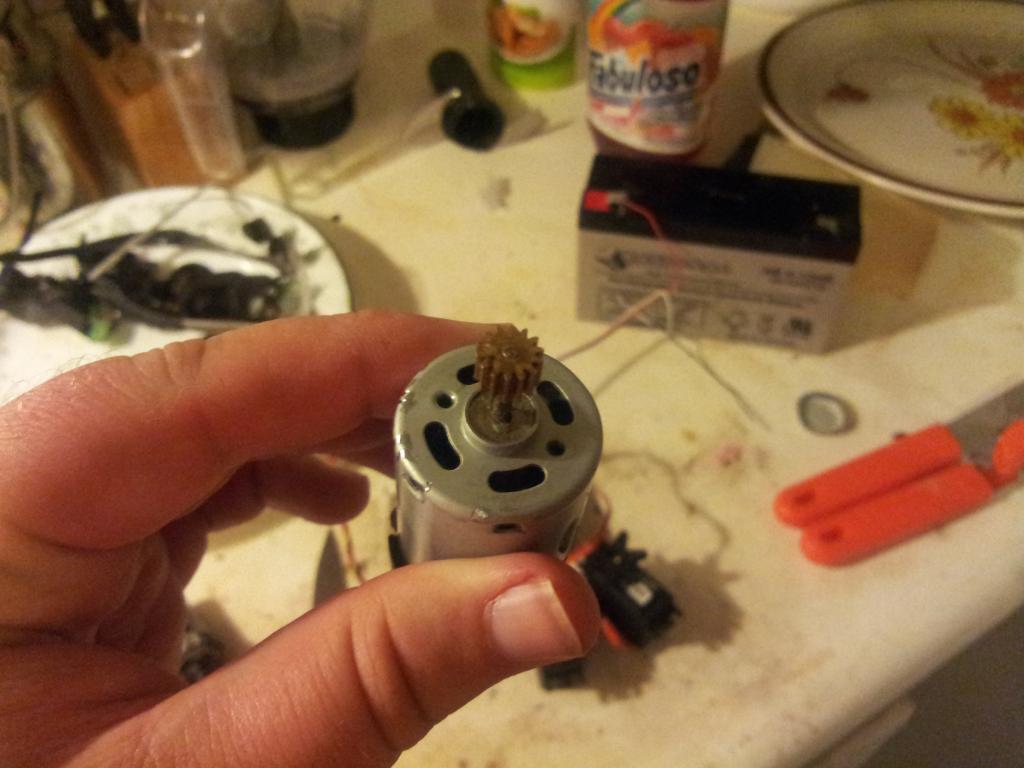
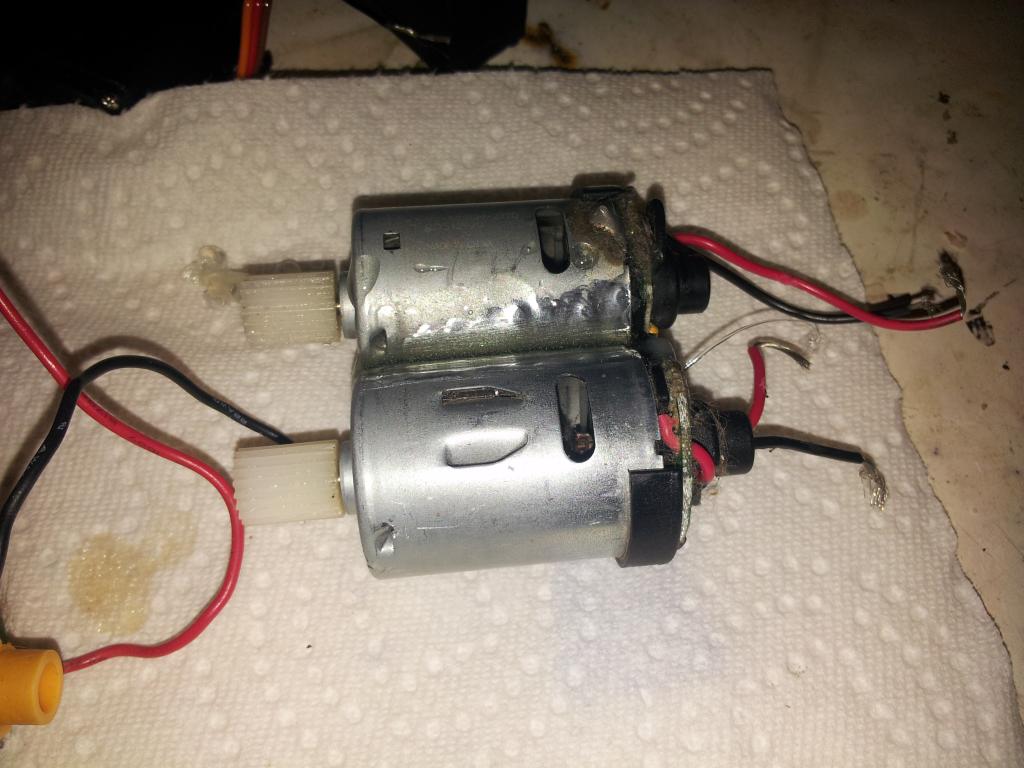
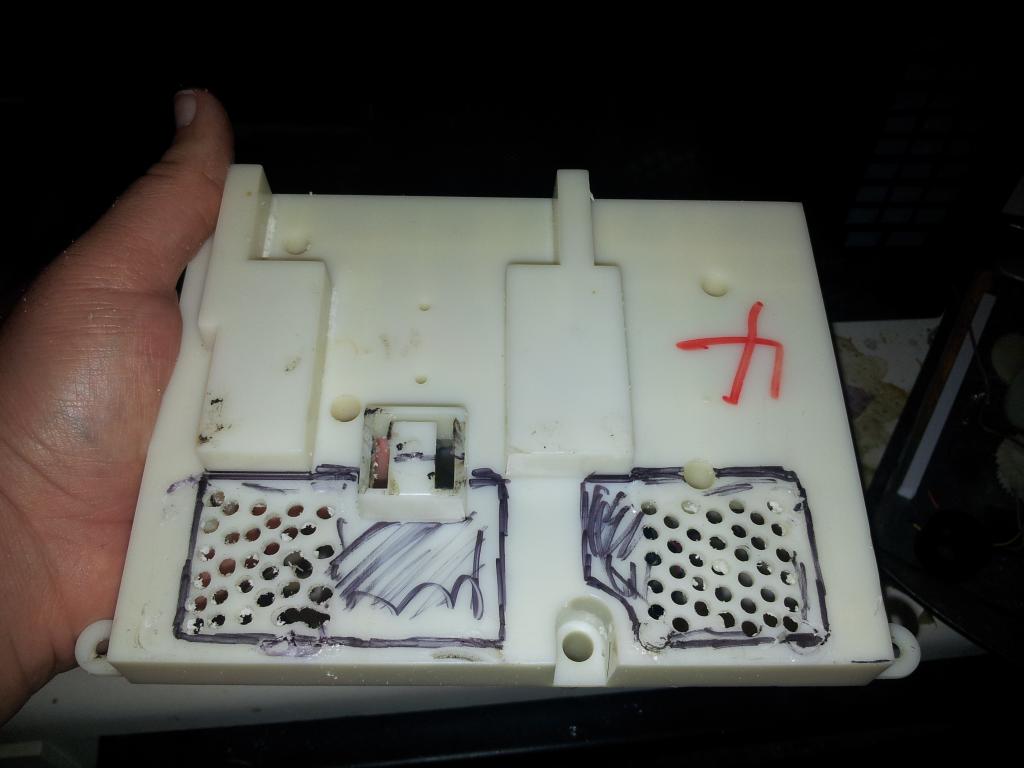
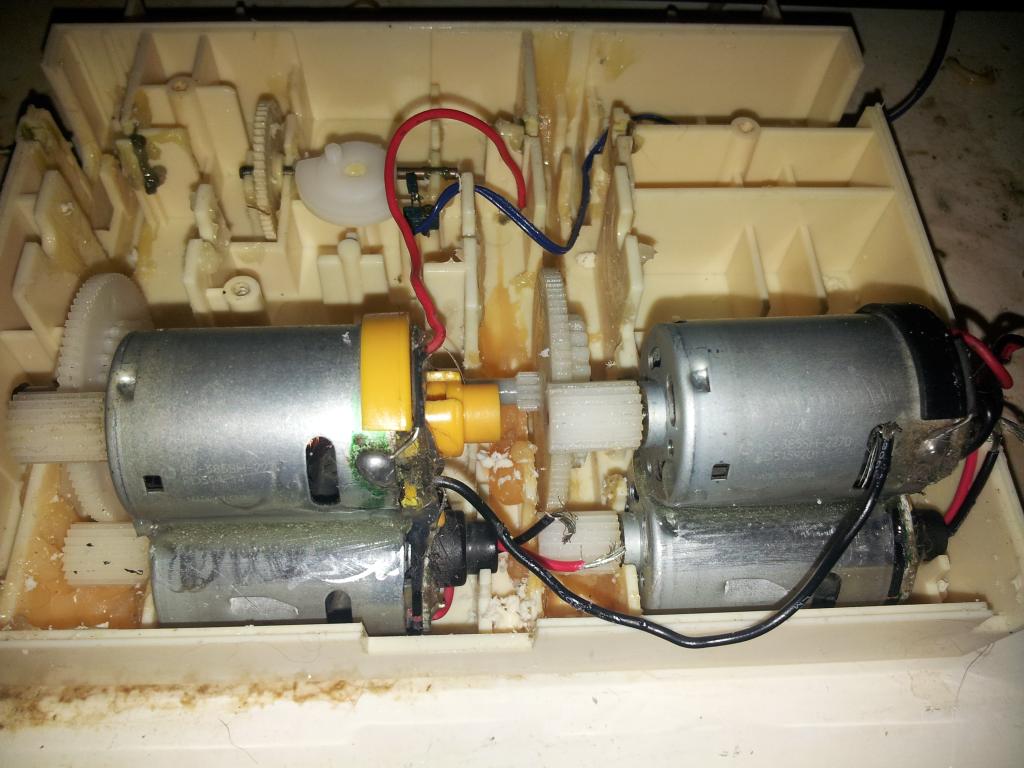
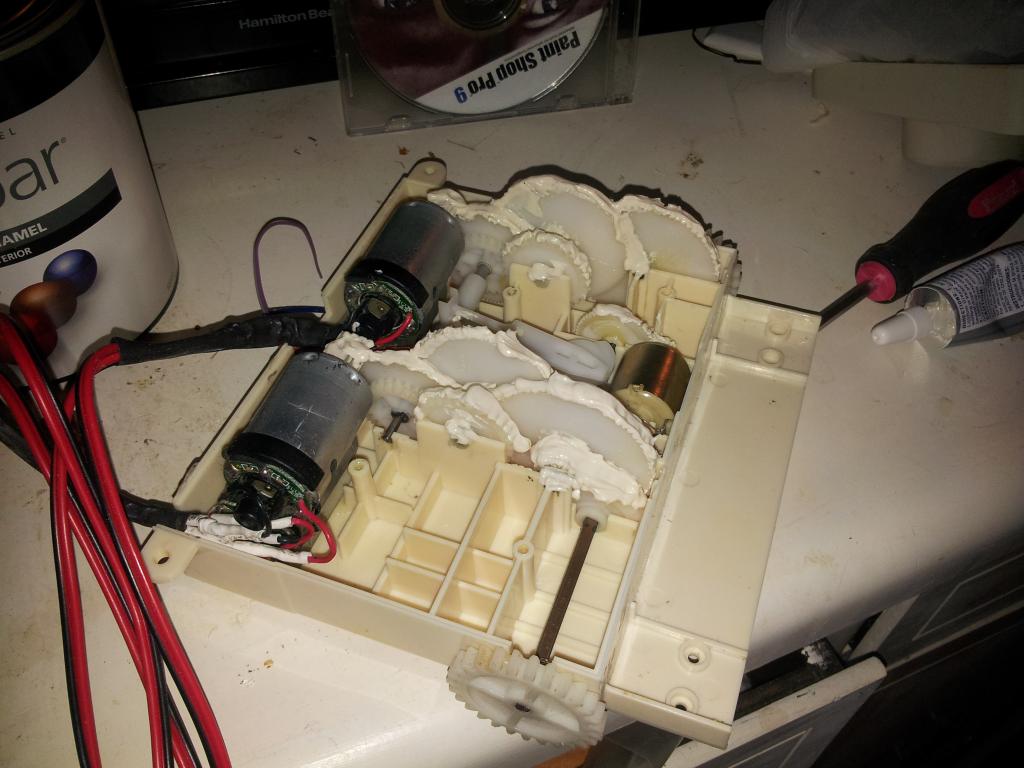
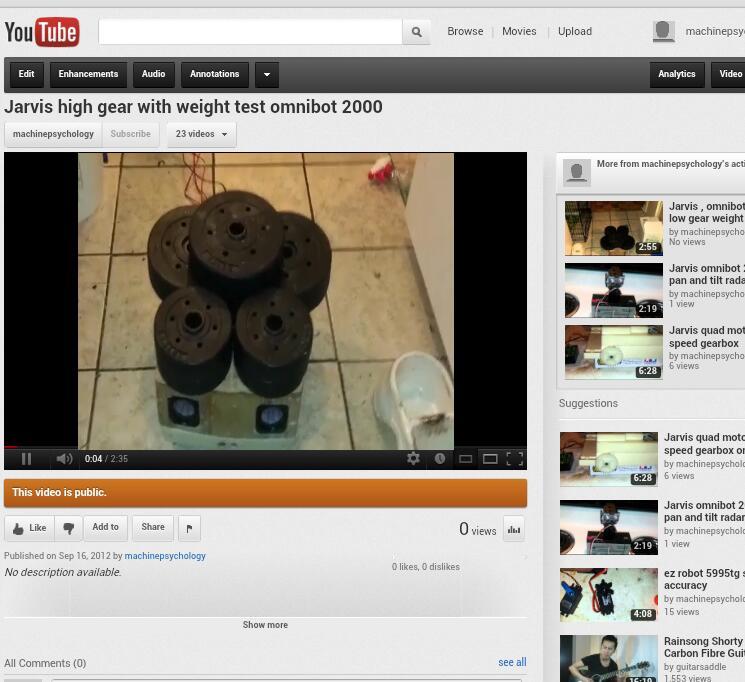
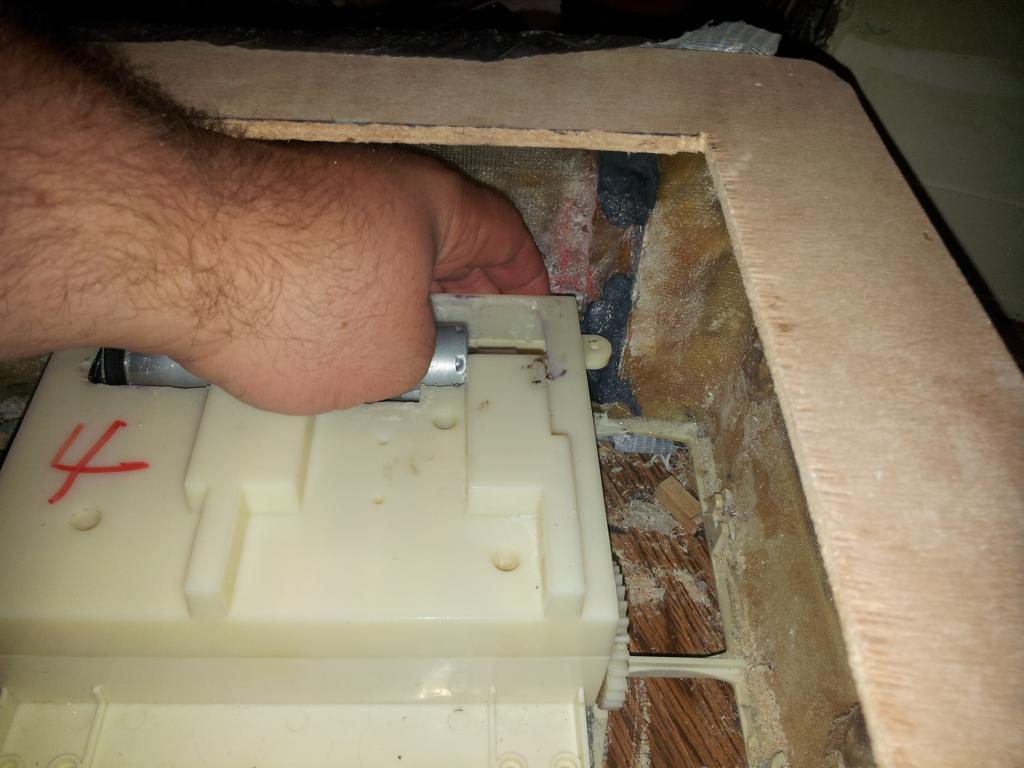
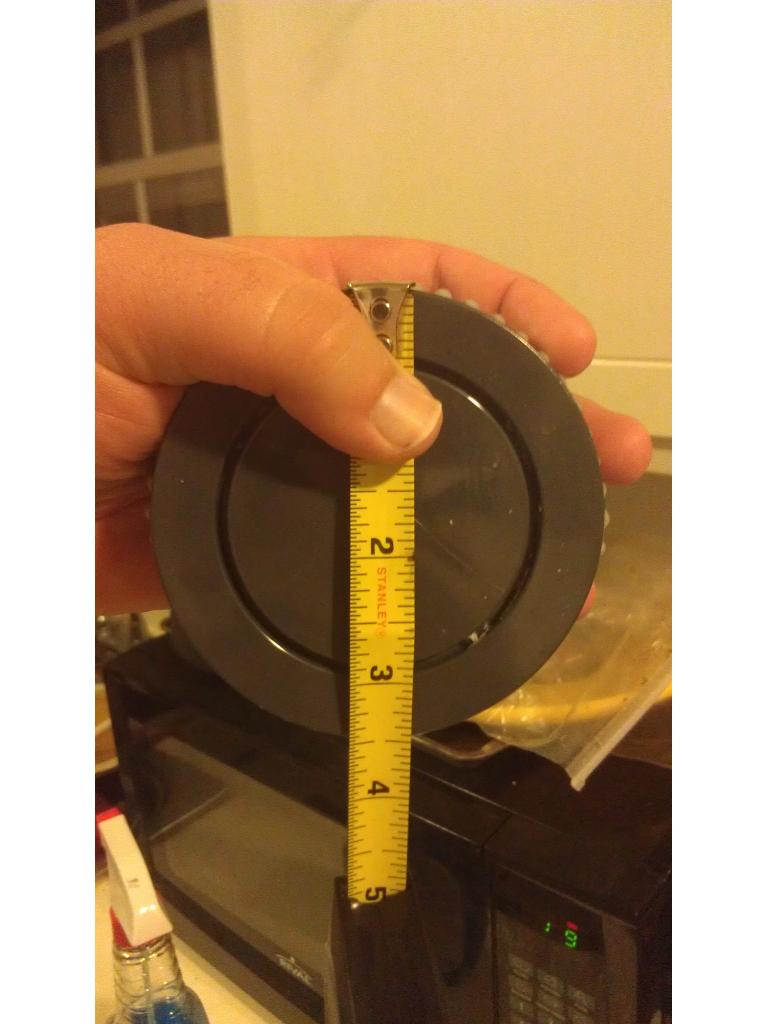
I tested the Omnibot drive section , it was able to lug around 40 pounds at a rate of around a foot a second I guess , I made a video , I will also check it on carpet as well but I don't think it will be an issue at all.
YouTube video... https://www.youtube.com/watch?v=QNT2SqCGiNo&feature=youtube_gdata_player
Is that with the stock motors and gearboxes? That is really impressive.