
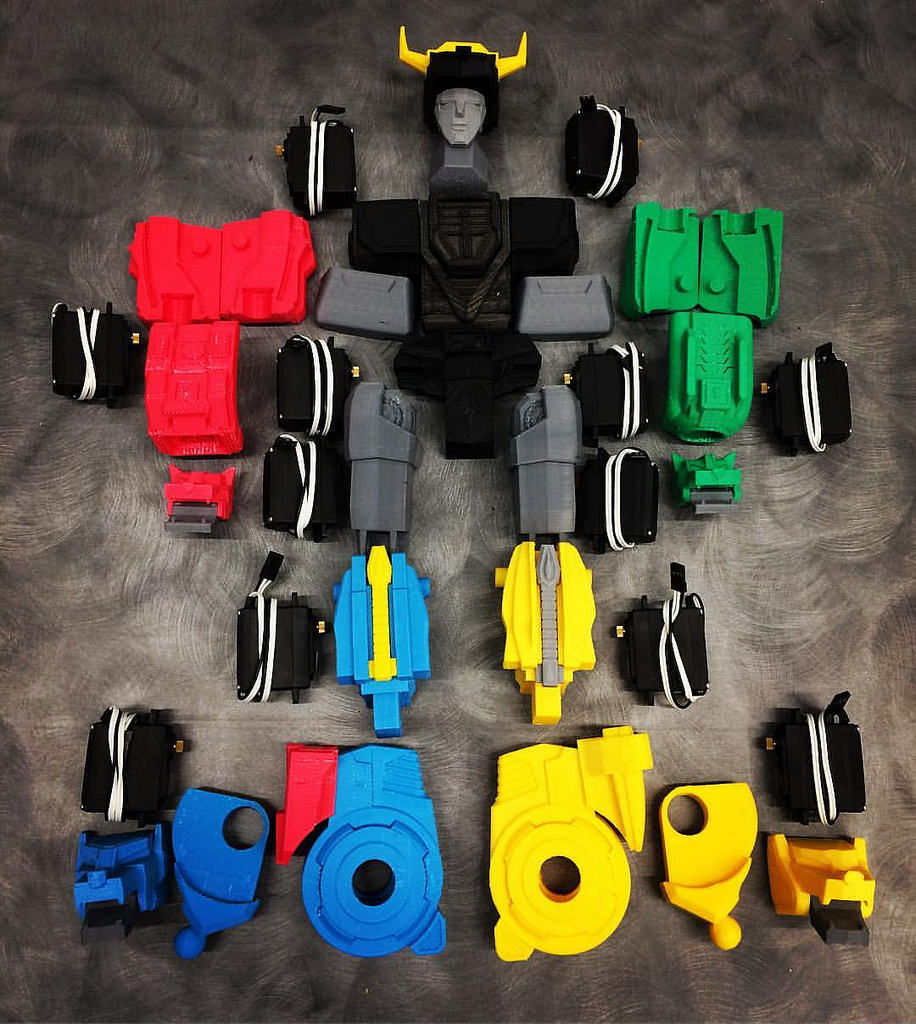
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.

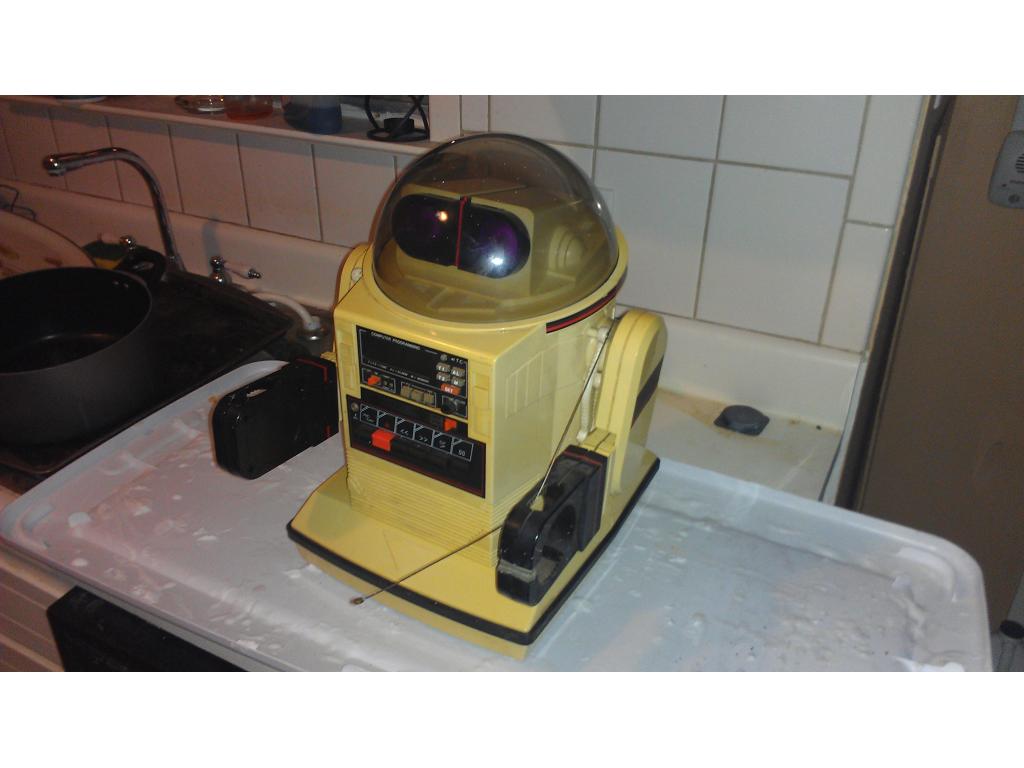
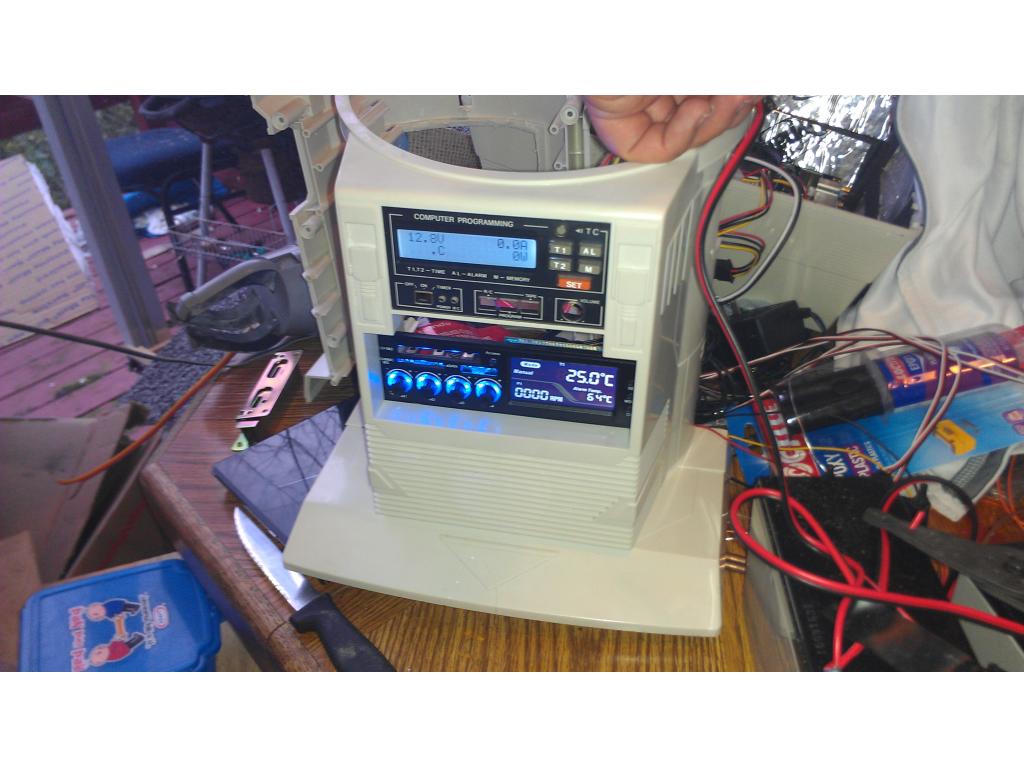

@josh about using LM3915 being using them for a very long time,to get 40 ,just need to cascade them in series
@troy yes I have plastic I will cut a blank out of and then on the inside of the shoulder I will reinforce it with a couple thin layers of fiberglass matt + resin. Just incase I have the "backup servo " option we talked about.
on how to cascade LM3915 ,output of divider string goes to input of the next LM3915 and so on i guess you need to have 10 on each side,so only 2 are cascade for left and 2 for cascade for right need any info on how to do it let me know
Yes I need info on how to do it , schematic and parts list greatly appreciated , been in the 115 degree weather I'm kicking back for a nap before starting to mod the arms
its about 90 degree's in fla
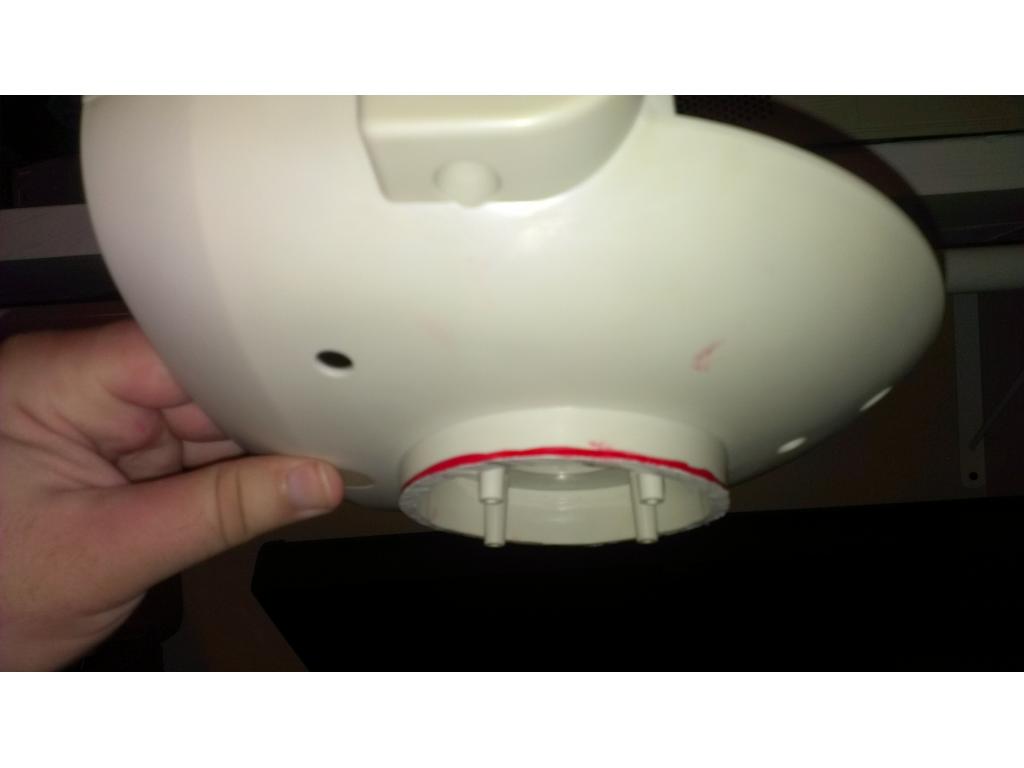
Cut down a inch off.the neck for better flexibility and range of motion , I left half a inch to keep the neck grommet centered.I filled in.the gap around the ultrasonic on his head.