I don't know if this will work, but here is a youtube link. This was my first attempt at uploading a video there. The file was done on an Galaxy Tablet, at 122 MB, I figured DJ would prefer it not take up space on his server.
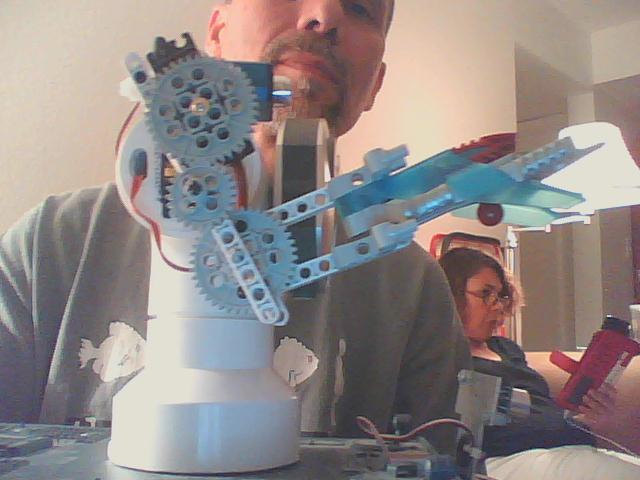
Dogbot has a bit of User operator error, but with a little more training It'll be run much soother. Next phase is to pickup a few more Servos to add a better head, and a left arm. At somepoint the wife (our resident knitter) will make a red sweater for the dog, so DogBot can track her. Given the reliablity issues involved with color tracking though, I'm leaning more toward RFID tracking.
By Dave L
— Last update

Discover more robots
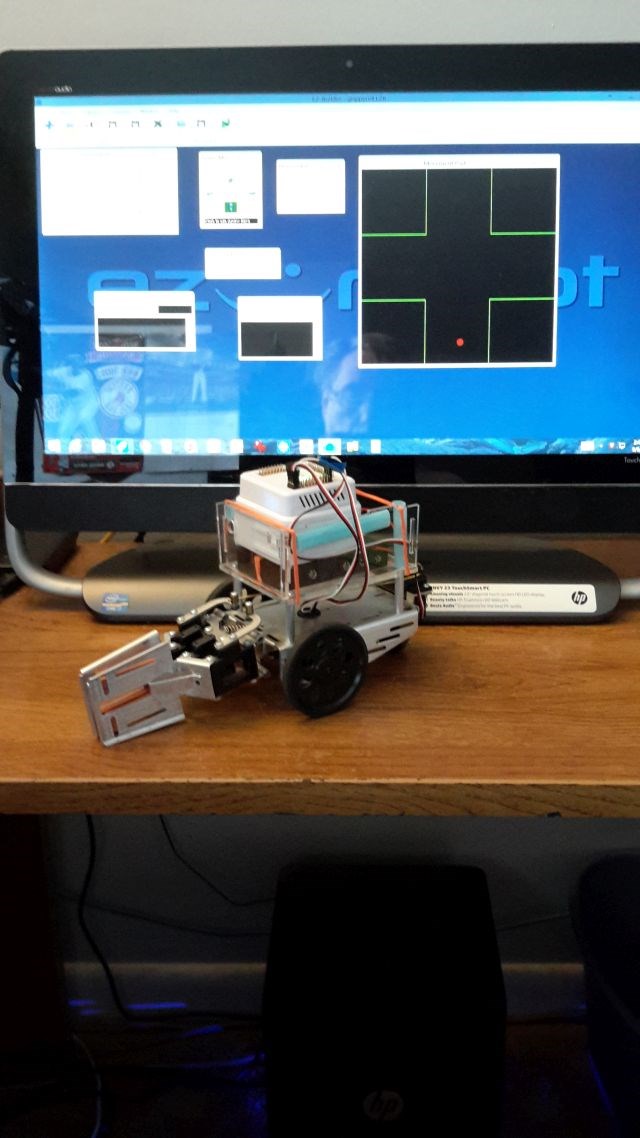
Jdebay's Gripperv4 Old Parts And New Parts
Build Gripper V4 from old and new parts; updated design now includes an added camera.
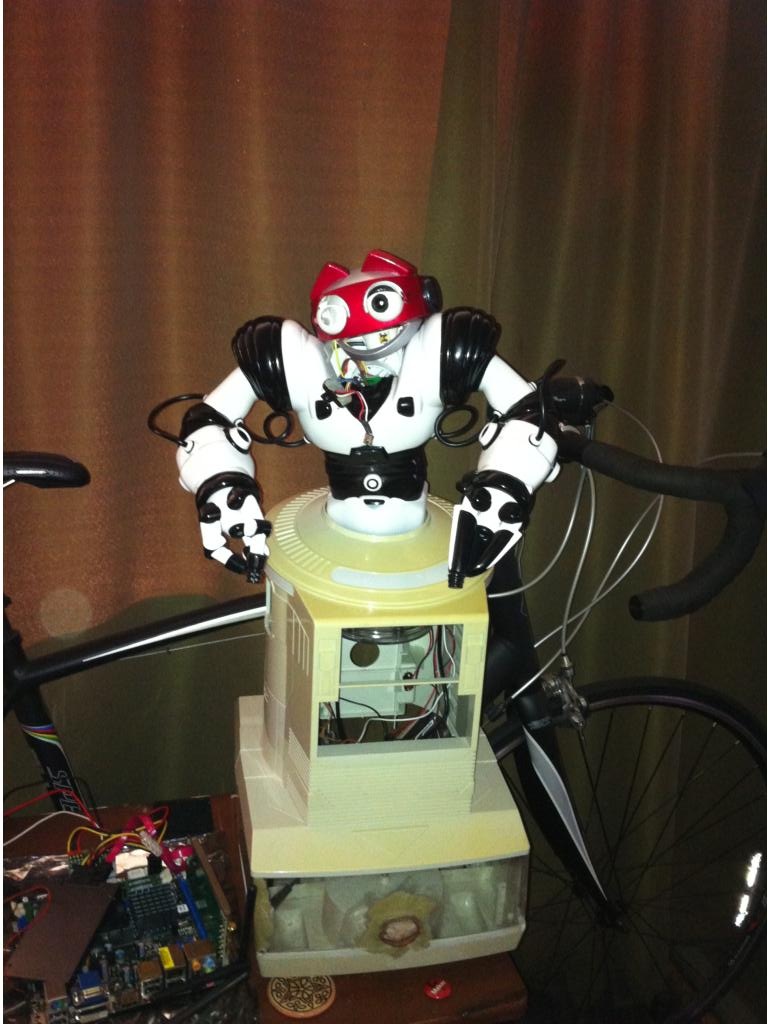
Sfoy's My Frankenbot - Robosapien, Hearoid, Ottobot Head
Build a custom hearoid omni bot base with mini-ITX, acrylic enclosure, IR sensors, cameras, pan/tilt, EZ-B integration...
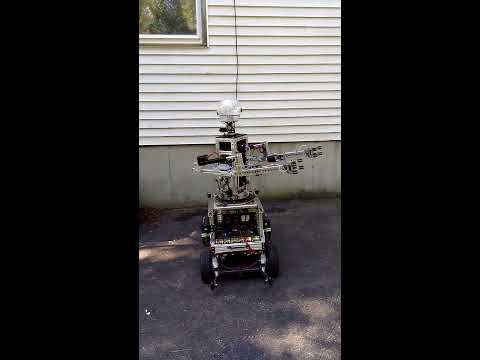
Jim's Armadeus Mk. 12
ARMadeus Mk.12 converts a power wheelchair into a modular robot base with EZB control, sensors, turret, arms, pneumatics...

Dave that was ultra cool!
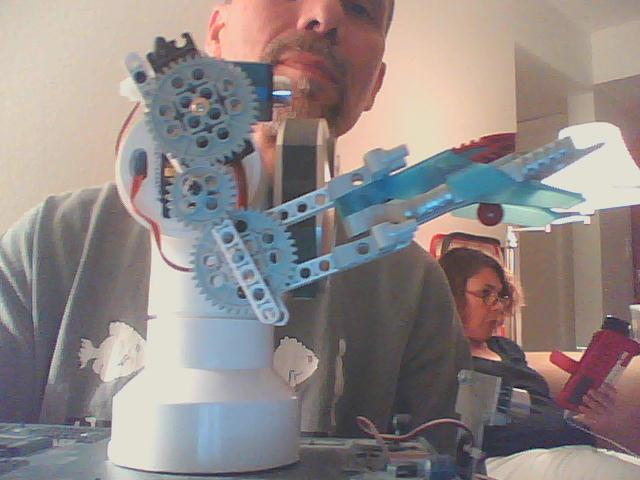
I would like a closeup of your arms and hands. And, where did you get them? did you build them? Or, are they were part of a toy. It looks like some use of PVC pipe. I like it!
Mel
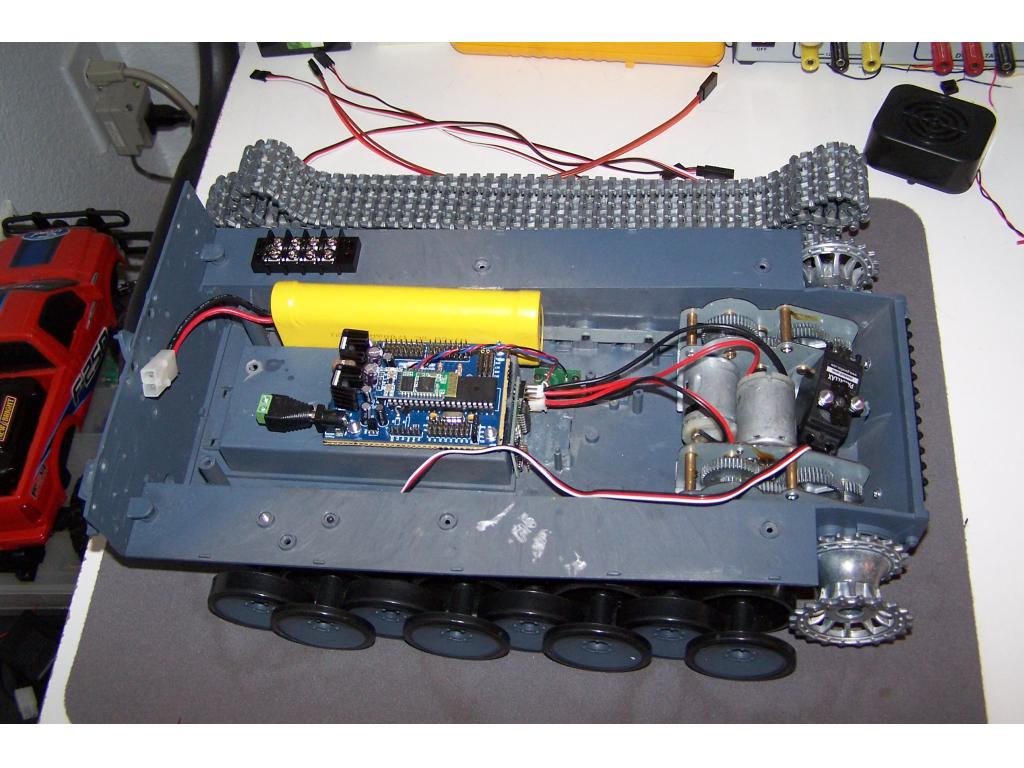
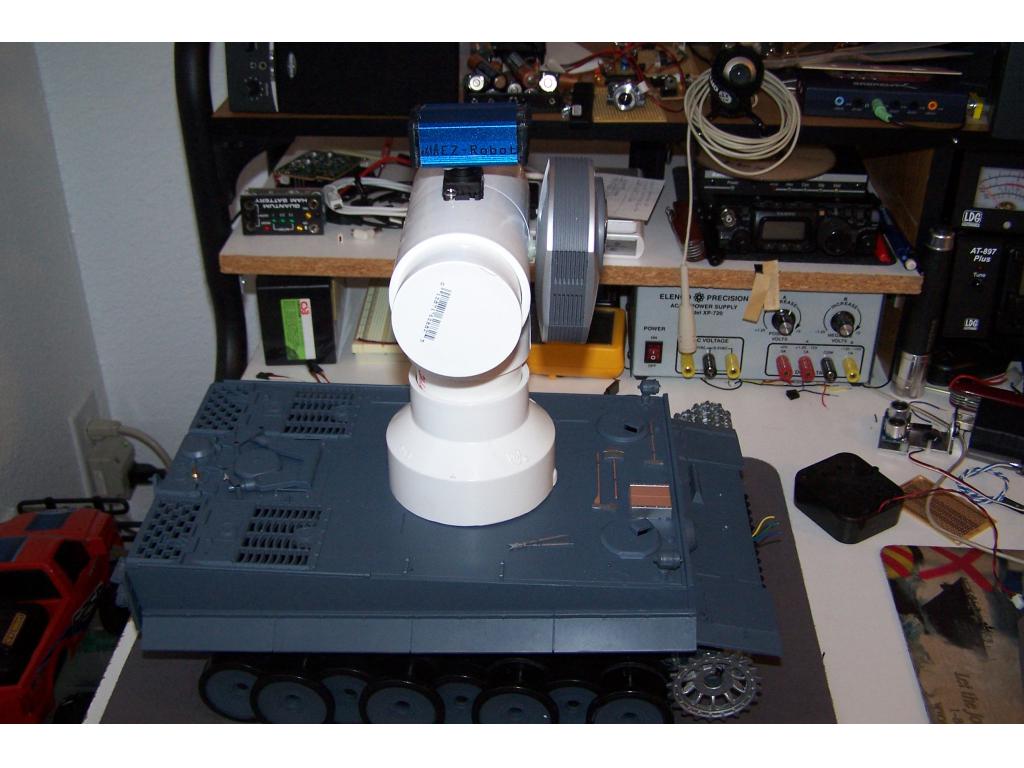
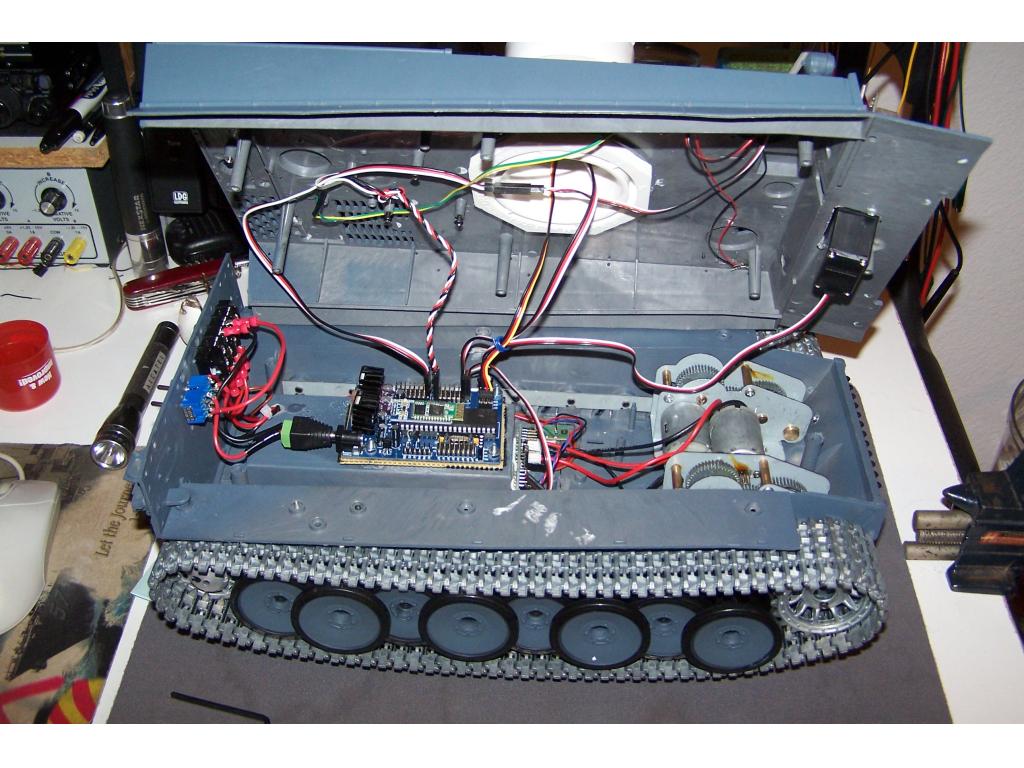
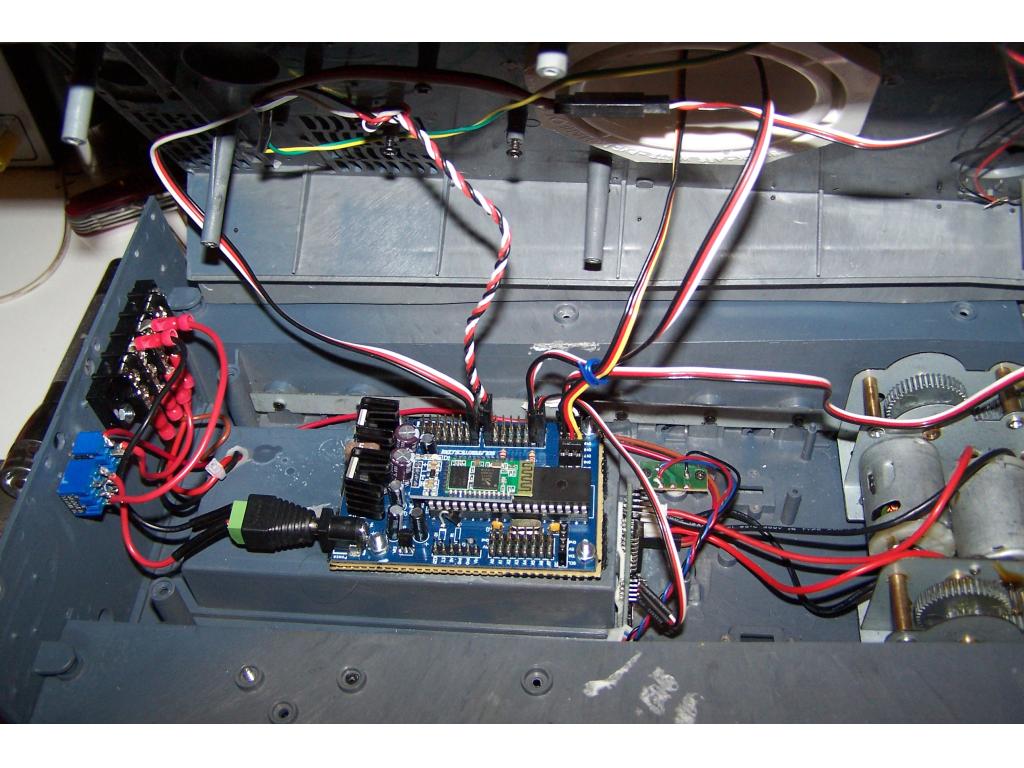
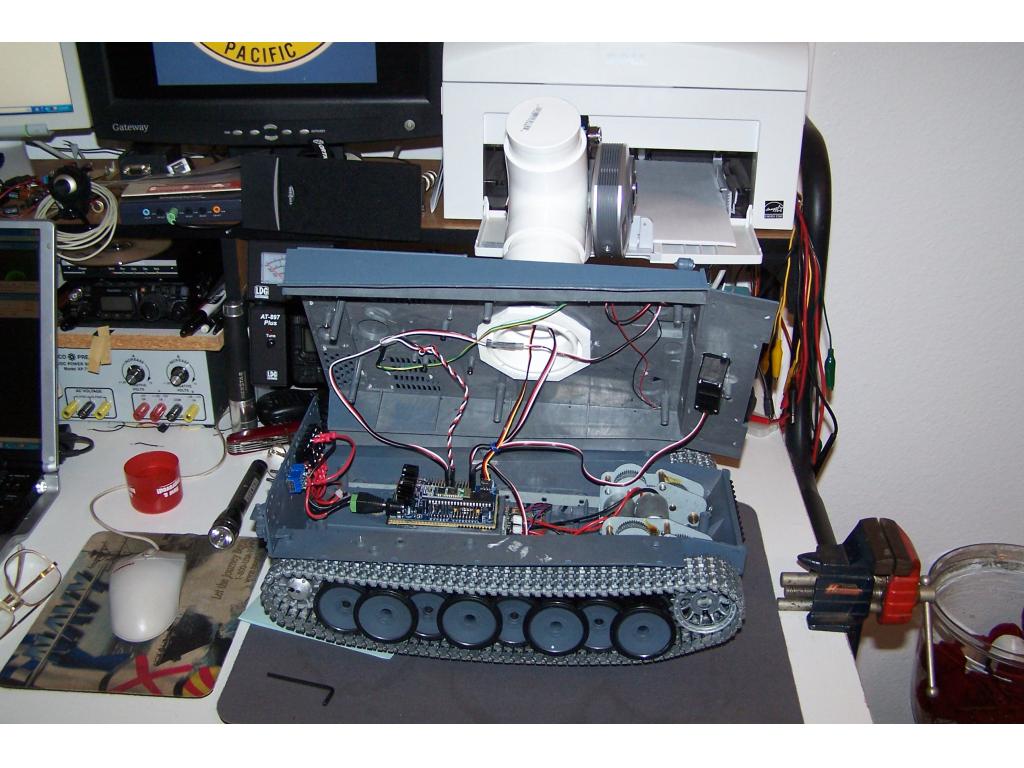
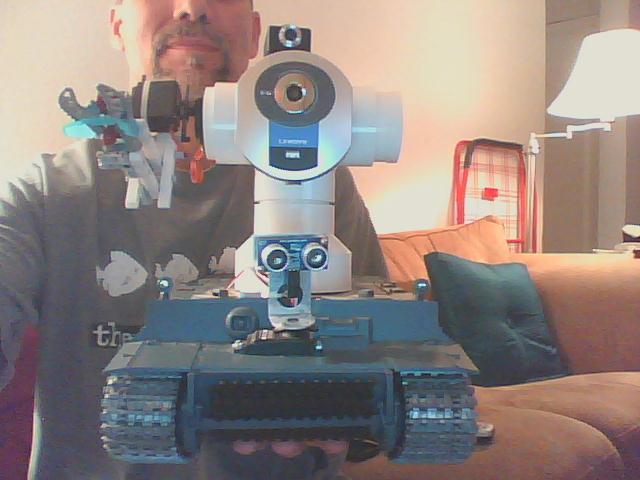
The Body is PVC Pipe. The Arm is Lego parts. The base is 1/16th scale Tiger Tank.
I do have to give credit to my Son on putting together the Lego arm, he did it at 2:00 AM. I then hack his Lego parts to the two Servos.
Just for ease. Very nice great job.
ThankS, I'll have to look into doing this for future posts.
Hey Dave thats a fun bot!!
Are you using the l298 motor controller?
Thanks DJ. I'm using a Sabertooth 2x5 Controller. The motors pull 3 amps when running full speed.
By the way, is there a way to adjust the speed via a slider control or joystick?
Sweeeeet!