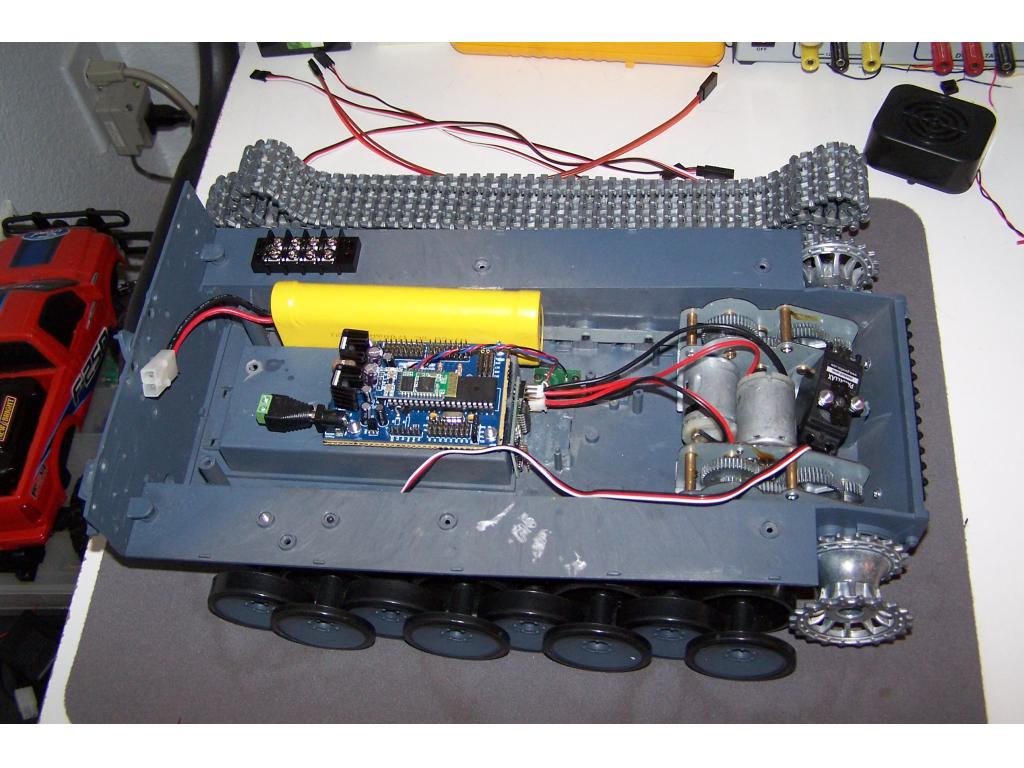
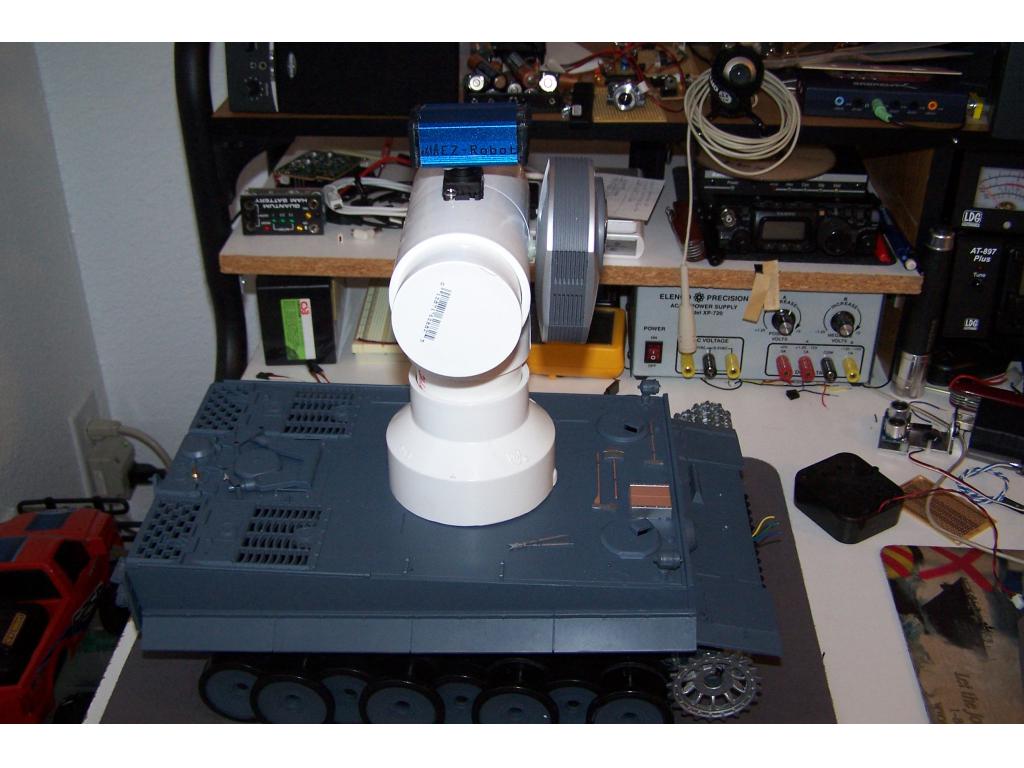
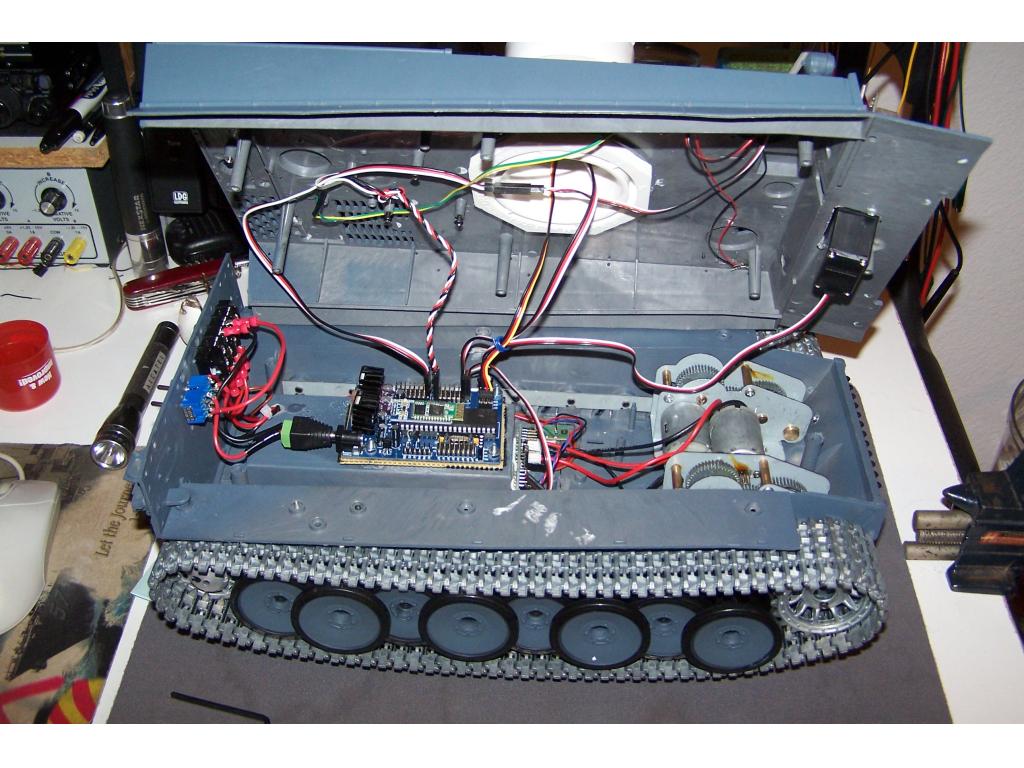
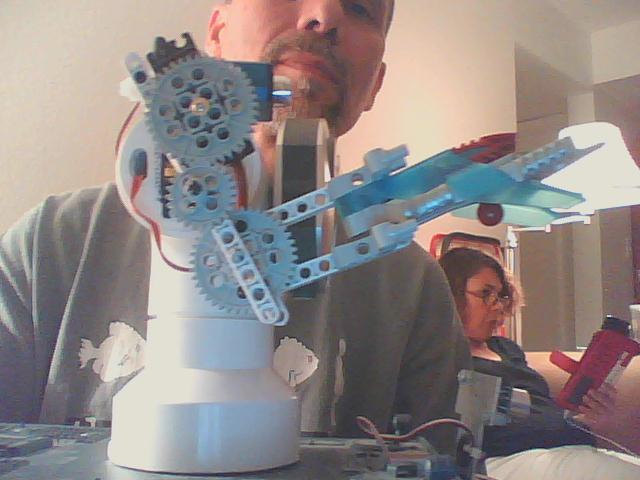
I don't know if this will work, but here is a youtube link. This was my first attempt at uploading a video there. The file was done on an Galaxy Tablet, at 122 MB, I figured DJ would prefer it not take up space on his server.
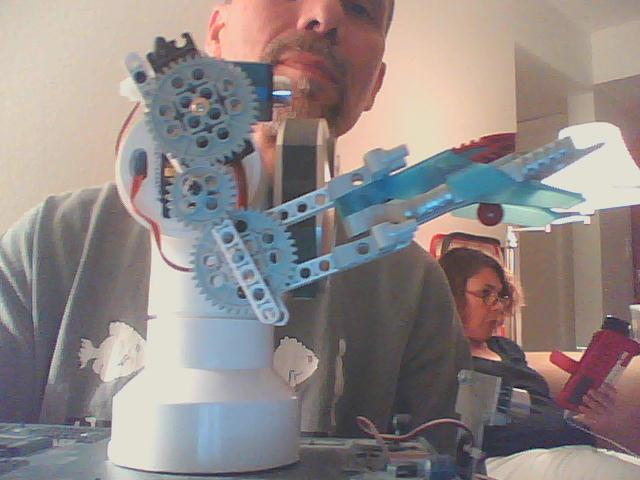
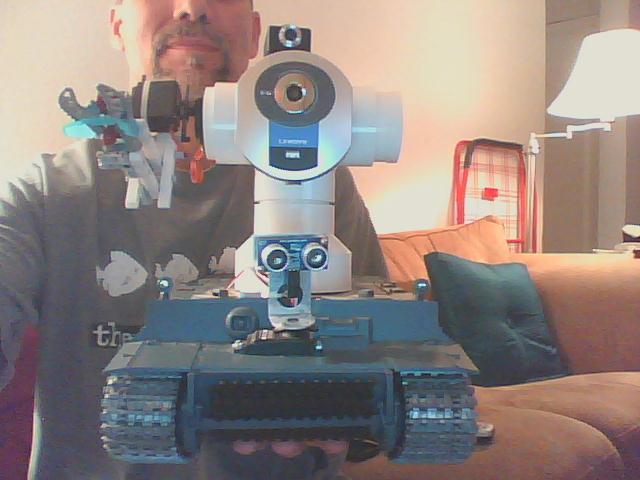
Dogbot has a bit of User operator error, but with a little more training It'll be run much soother. Next phase is to pickup a few more Servos to add a better head, and a left arm. At somepoint the wife (our resident knitter) will make a red sweater for the dog, so DogBot can track her. Given the reliablity issues involved with color tracking though, I'm leaning more toward RFID tracking.
By Dave L
— Last update

Discover more robots
Jim's Armadeus Mk. 11
ARMadeus Mk.11 - 140 lb modular robot with EZ-B v4, universal base, interchangeable turret with dual pneumatic NERF disc...
SBANAS09's Kitty Hawk
Engage 7th graders in STEM with Kitty Hawk aviation program: wing design, watercolor flight art, and EZ-Robot coding to...
Drephreak's New Robot
Hexapod using EZ-B and Synthiam ARC-walking in 2 hours; easy programming, aluminum chassis, servos, sensors, planned...

Sounds like he has a lot of power. Great job!!
Dave, press CONFIG in the Sabertooth Movement Panel and change the values to the speed you desire
Nice work Dave - I wish I had treads like yours - did you build them yourself or get them fom a kit ?
@Hazbot
they look like a tiger tank kit chassis .I used to have one a few years back.
DJ, I got that part worked out changing the values. I was hoping there was a way to change the speed on the fly.
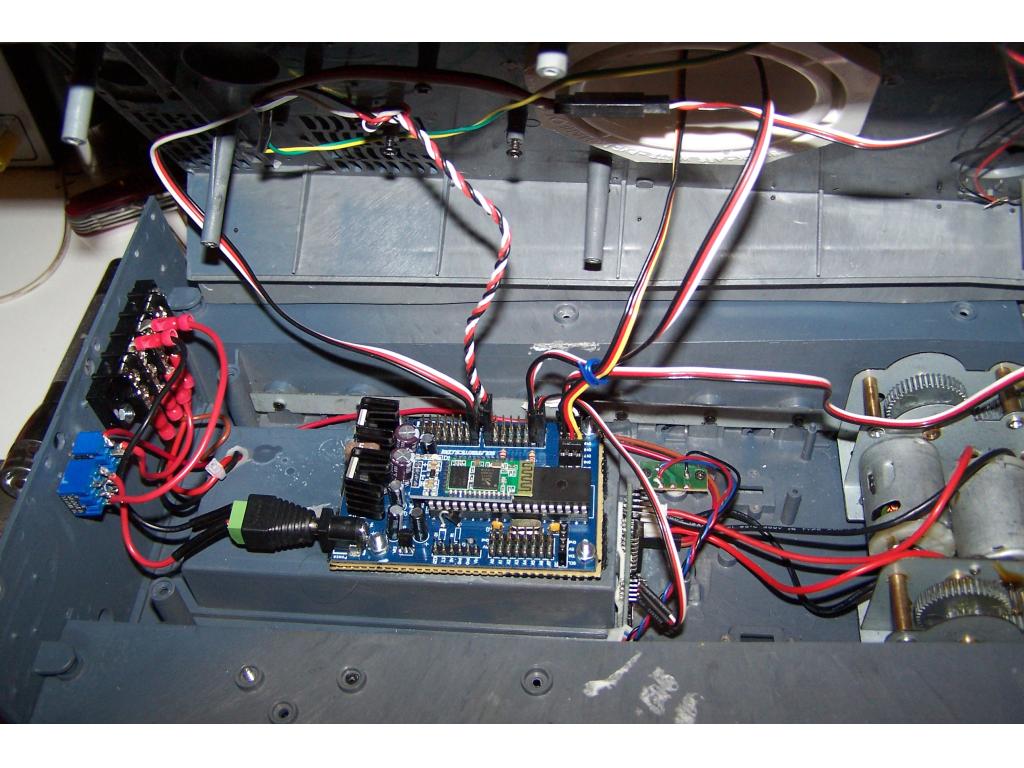
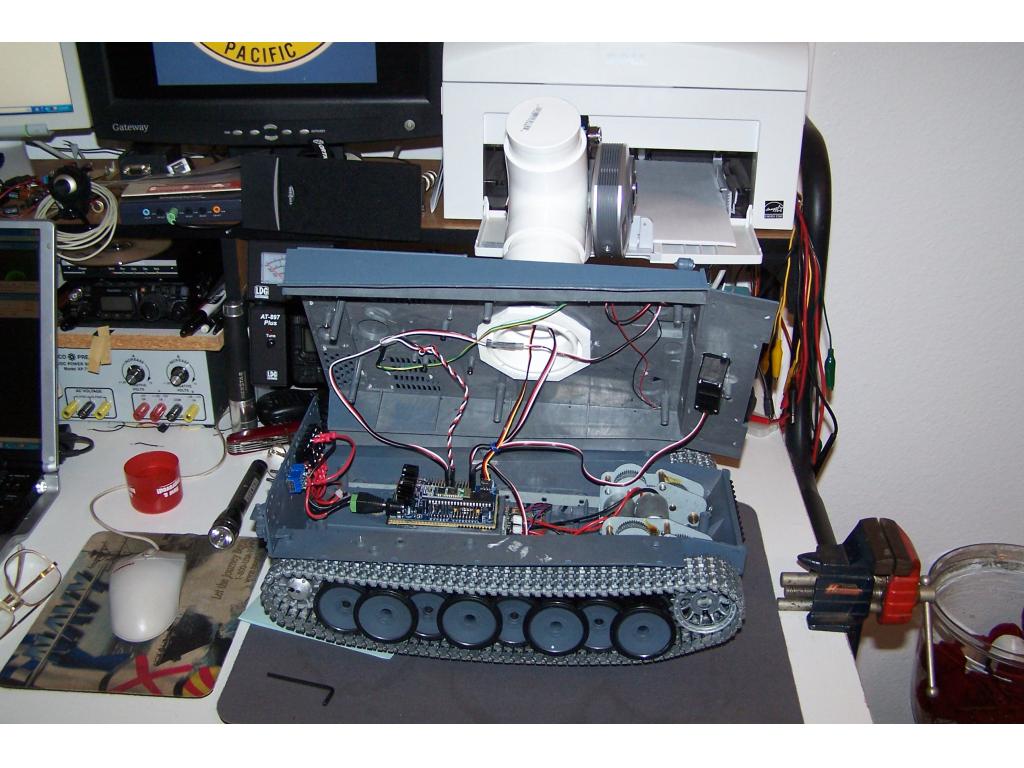
Steve is correct the base and tracks are from a Recycled R/C Tiger tank.
Oops clicked on the wrong Pic.