Gang,
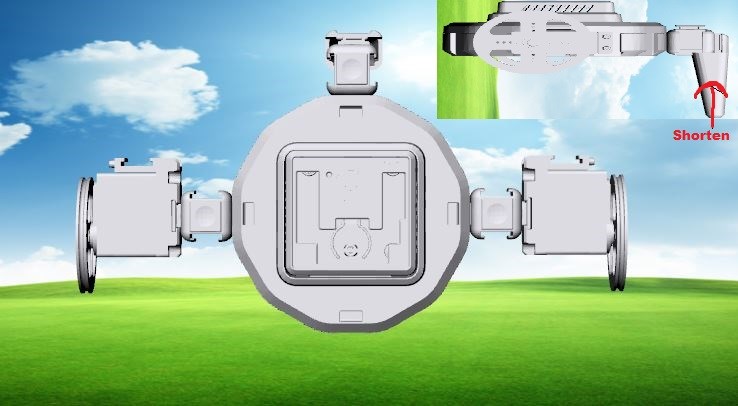
I'm working on creating a simple bot to play with that's designed around the Dev Kit Components with either 3d parts printed on your own, or by the community, any suggestions are appreciated.. The picture doesn't show the arms yet.. I also plan on adding the Camera and the Sonar..
Parts needed to print, Buy..
Qty Name 1 Hexapod Body 1 Extension Cube 2 Lever servo - 180 Degrees 2 Continuous Rotation Servo 1 Hexapod Foot (modified - Shorten)
By Morbeious
— Last update




Discover more robots
Ezang's My New Talking Mr. Head Robot
Mr. Head robot with jaw movements and more to come; I will be meeting AIMLbot soon
Bhouston's Inmoov's New Gripper
3D-printed syringe-powered universal gripper adapted for InMoov arm; picks up small objects; EZ-Robot OS enables easy...
Jstarne1's Build A Giant 3D Printer , Live Build, Come Join...
Unboxing Folger FT-6 large-format 3D printer kit with 3-camera views; full build livestream planned to print larger,...

That's an awesome robot idea!
Ha, ha... awesome.... just need a castor wheel ez bit....
@Richard r I'm going to shorten/widened the hexapod foot and put a ballbearing in it. That should do the trick..
Two words... "Balance Bot"
There were examples of balance bots running on just 2 wheels back in the EZ-B V3 times, with the uprated power of the V4 it shouldn't be too difficult to detect the platform's angle and move the servos to keep it nice and level...
@rich yeah, I thought about that.. but I wanted to create a bot with just what was included in the Dev Kit, and only ez-bit parts.. If I modify more parts and reduce the 6 AA battery pack to a 7.4 lit pack it would be a lot easier to achieve a balance bot.. but maybe not for the average Dev Kit owner.. I trying to create somthing that anyone with the kit should be able to create with little or no modifications of ez-bit parts, etc.. But it is a good suggestion..
thanks..
My first box bot used plastic skids for the rear and rotation servos for the wheels, and it was a pretty good solution (I used 3M Command Hooks as the skids). I think your idea of a shortened Hexapod foot would work well.
Alan