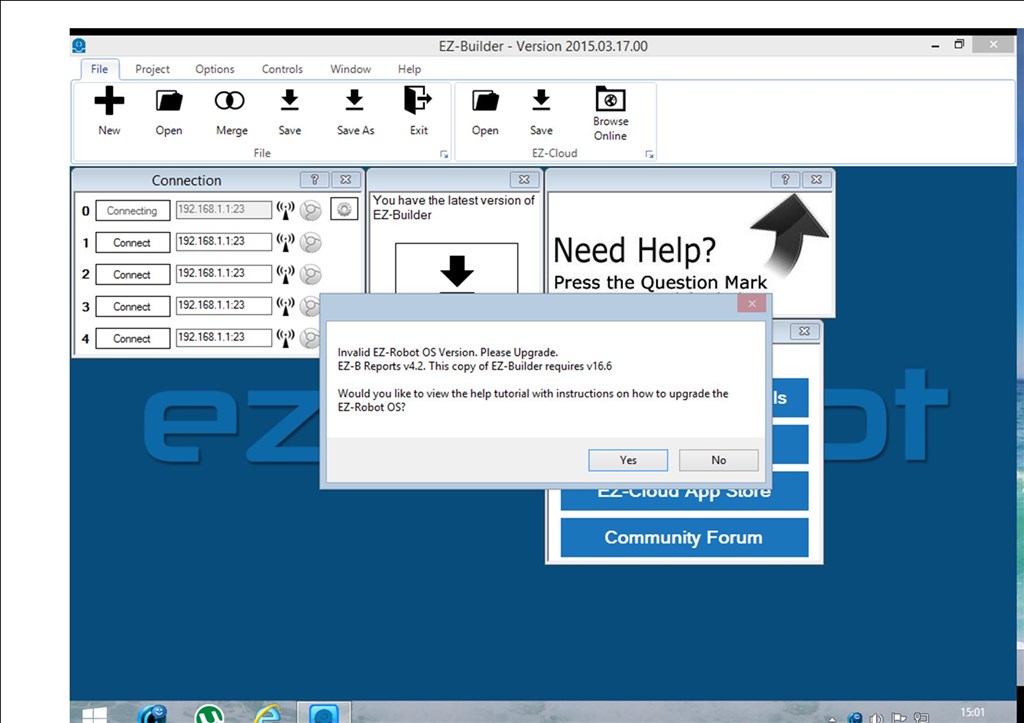
am having problems connecting to v4 keep getting this report
Quote:
21/03/2015 15:22 - Attempting connection on 192.168.1.1:23
21/03/2015 15:22 - Connected to 192.168.1.1:23
21/03/2015 15:22 - EZ-B reports EZ-Robot OS v25.5
21/03/2015 15:22 - Connection Failed: System.Exception: This device is not an EZ-B. Please follow the online tutorials on the EZ-Robot website.
at EZ_B.EZB.Connect(String hostname, Int32 baudRate)
21/03/2015 15:22 - Disconnected
I've had no trouble getting connected in the past I've had the v4 since December
tried resetting v4 still no luck
any help would be appreciated thanks
 Resolved by

Why is everywhere 192.168.1.1 ? The important ip address.
Internet is a great resource. It's called a private IP address. They are addresses that will not work on the internet but only work in your local area network. More here: https://en.m.wikipedia.org/wiki/Private_network