
Hey,
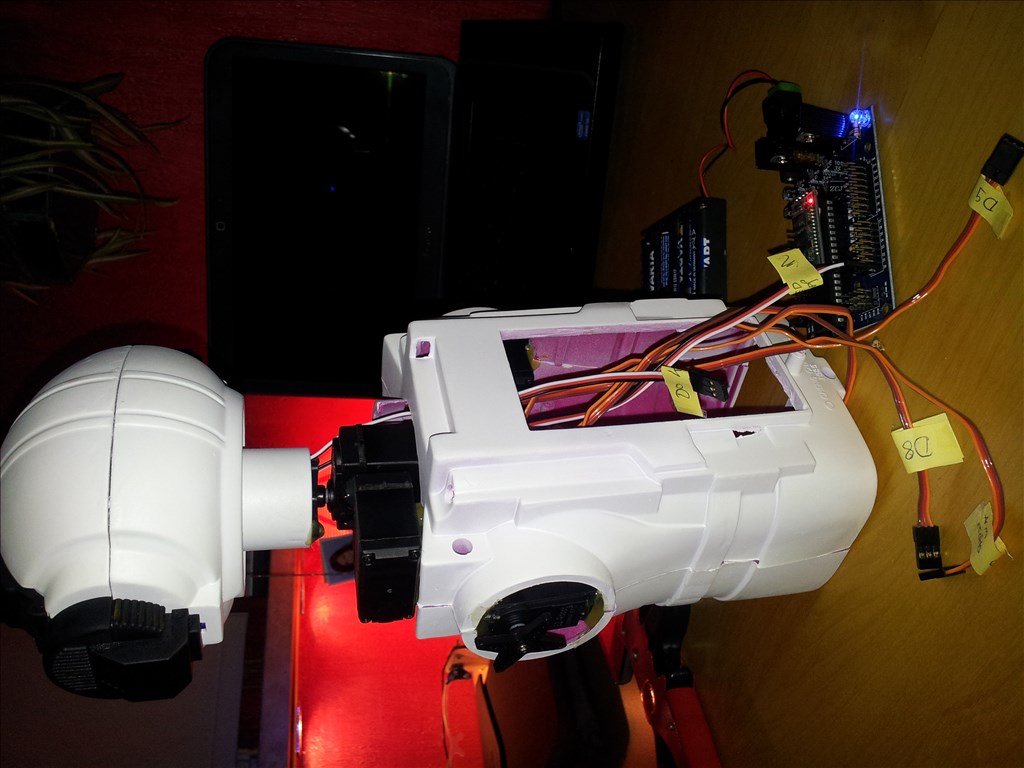
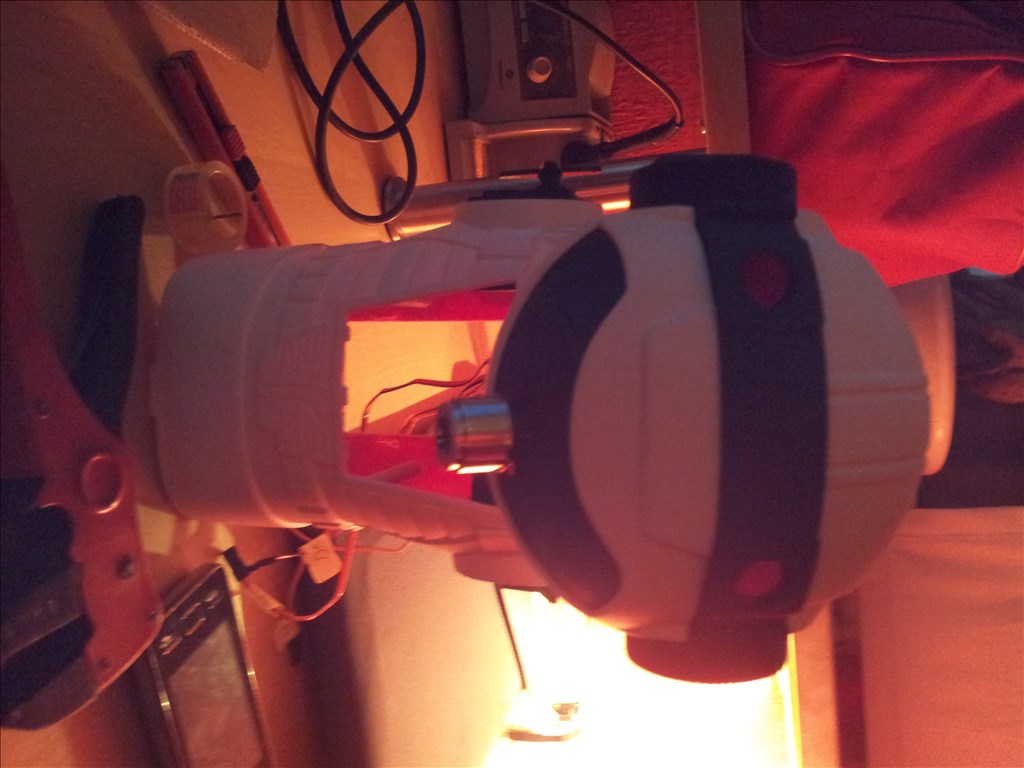
here´s my first robot-project.
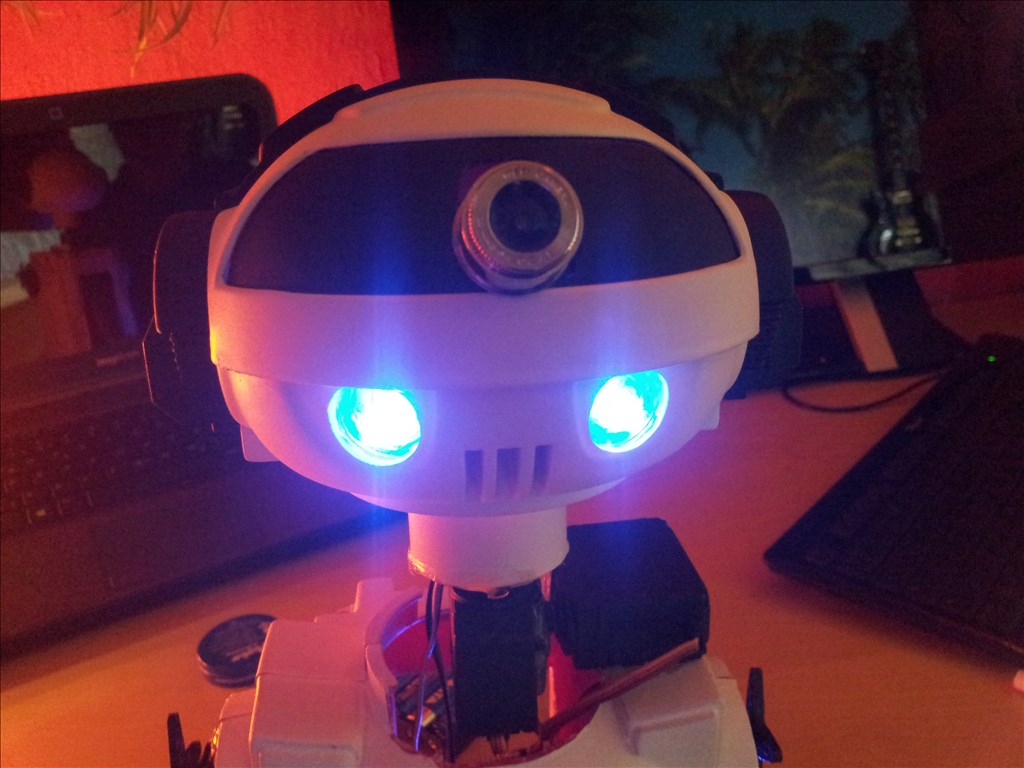
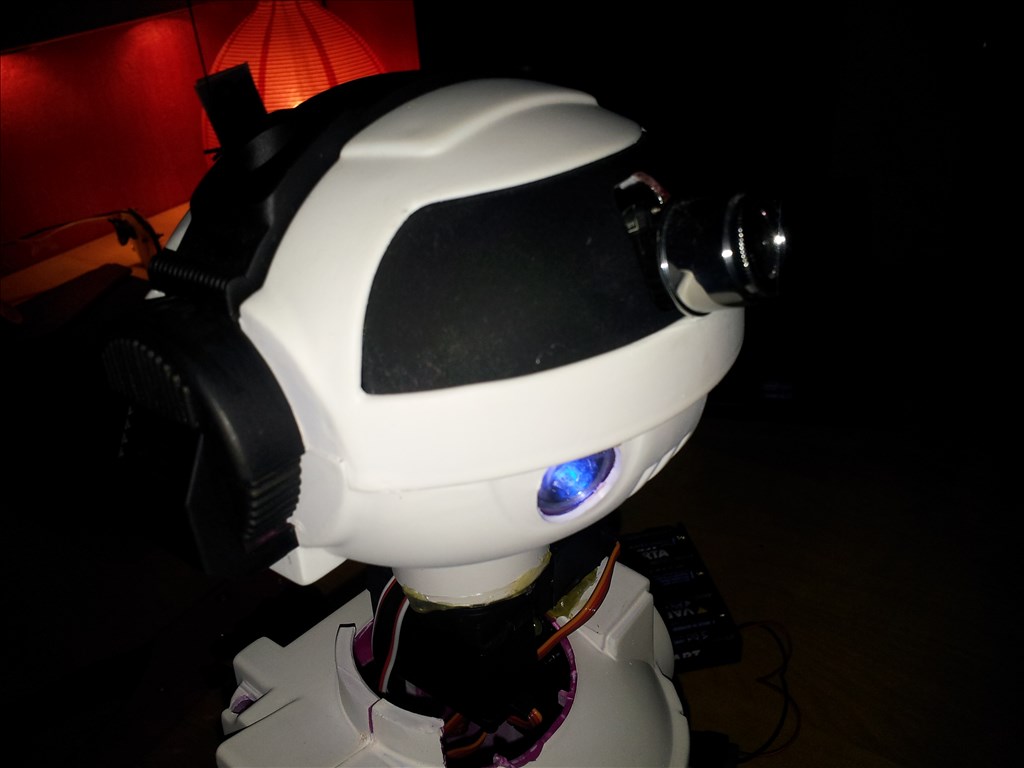
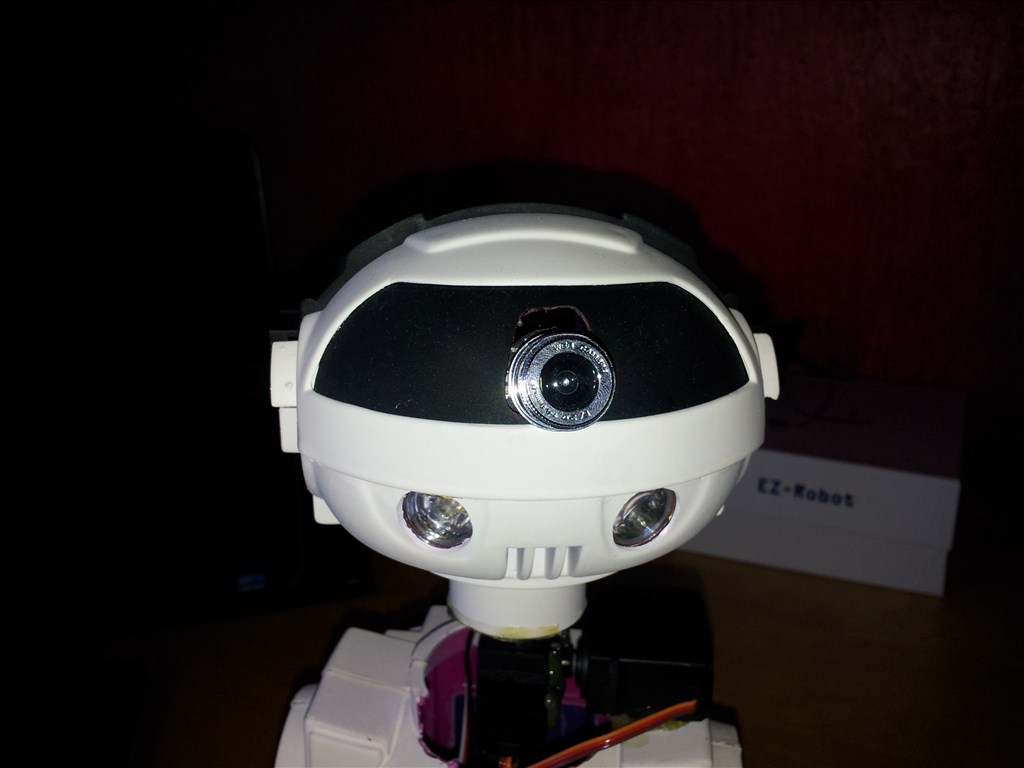
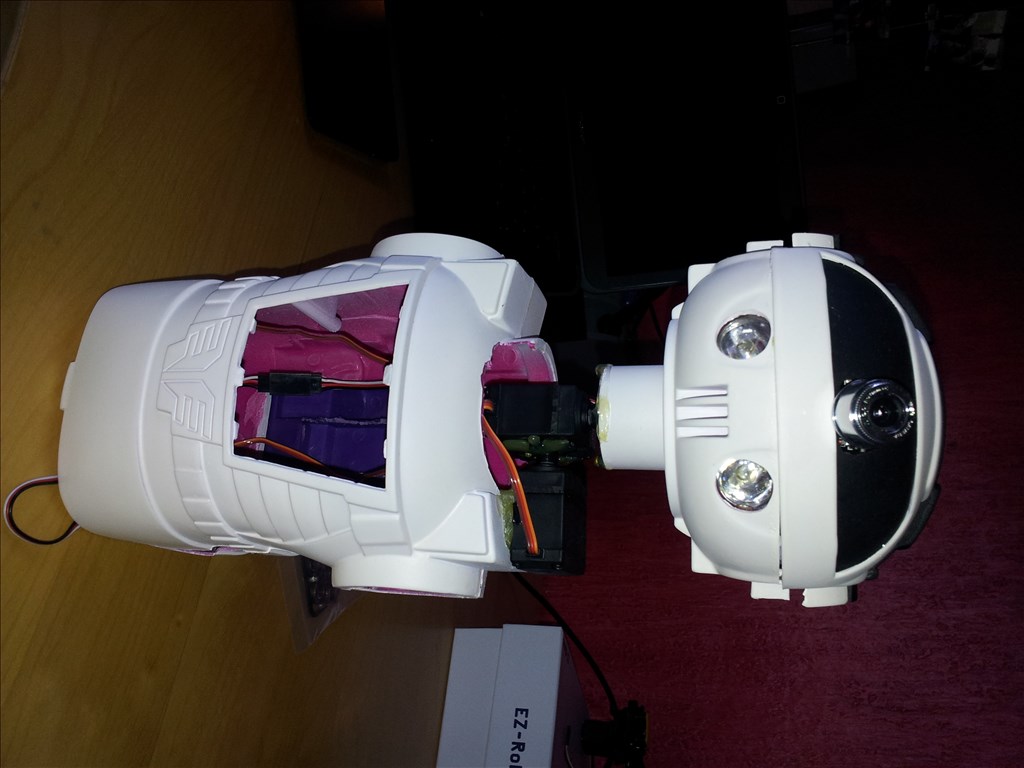
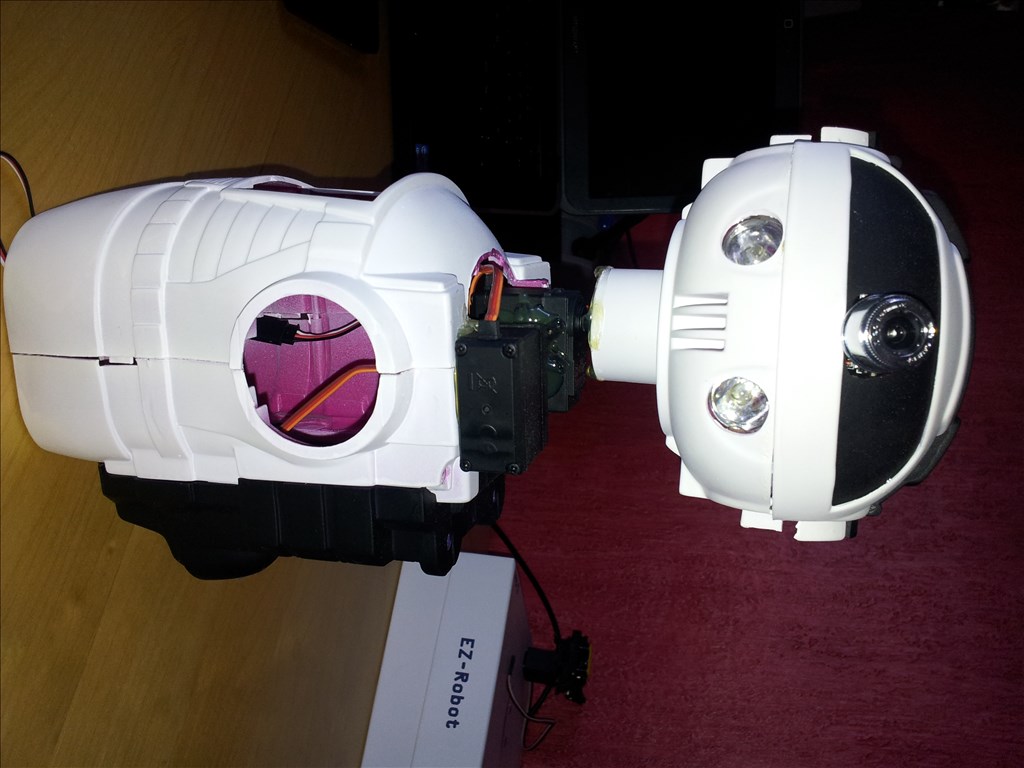
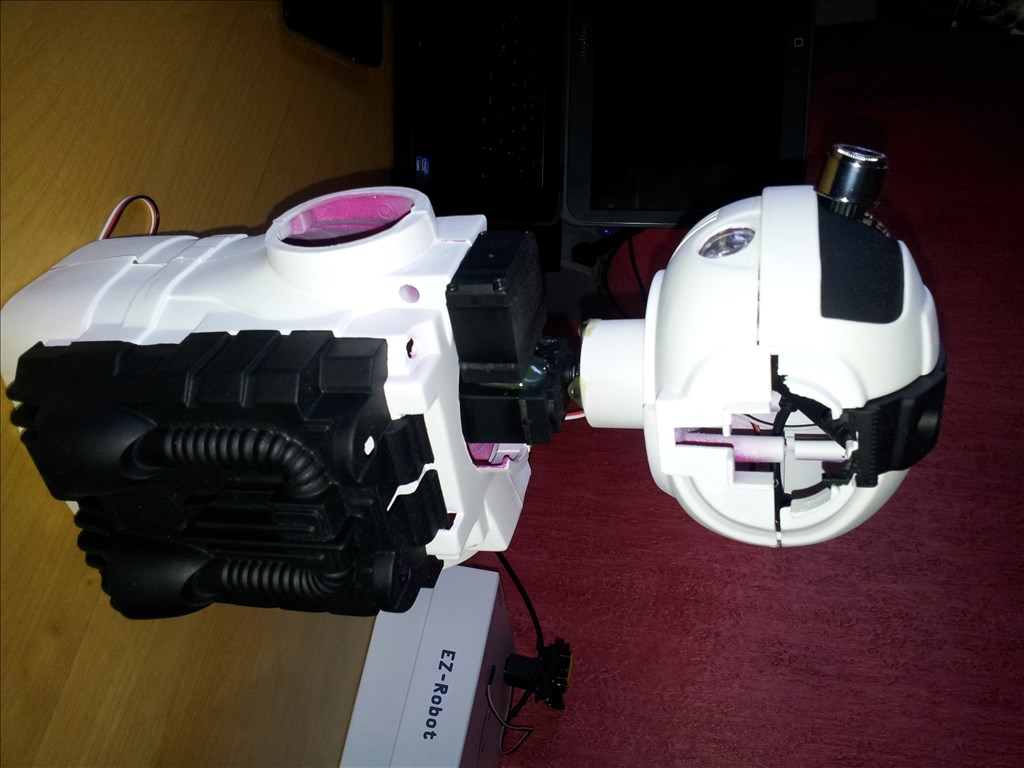
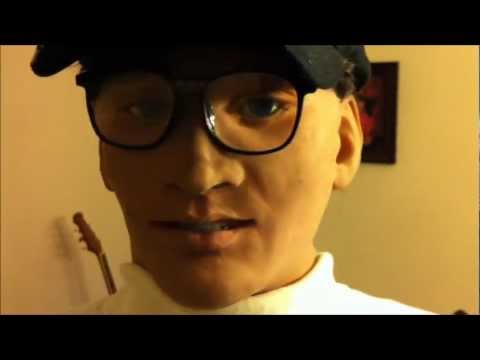
I proudly present "MARVIN" tadaa
As you can see, I´m still working on it ...
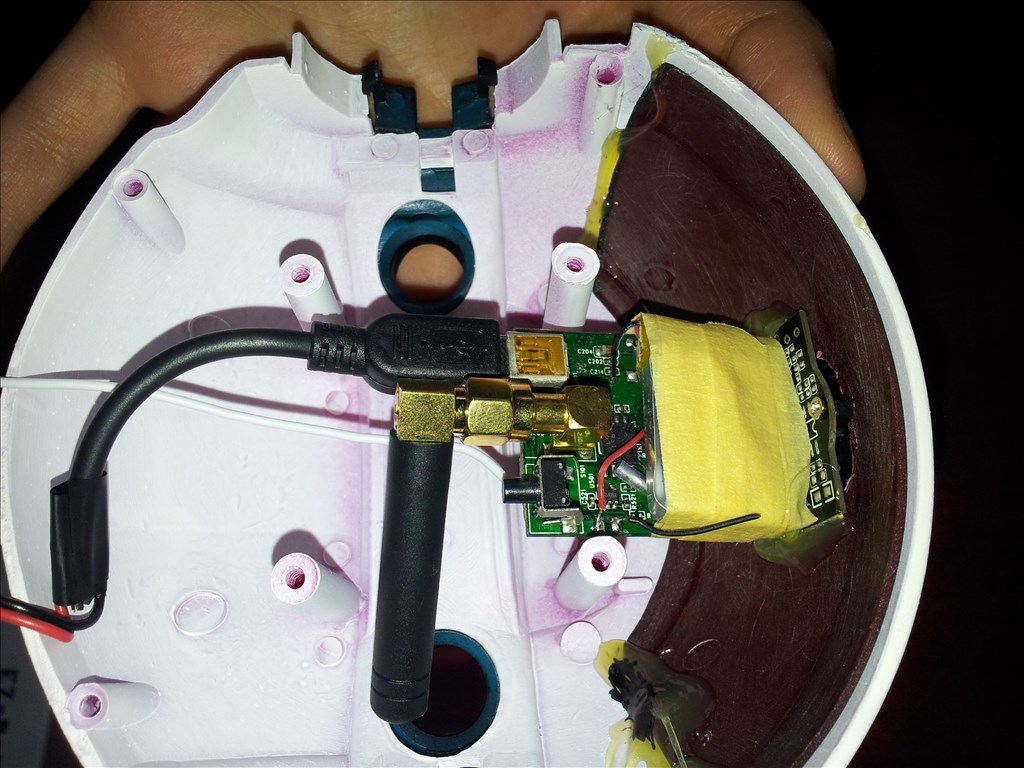
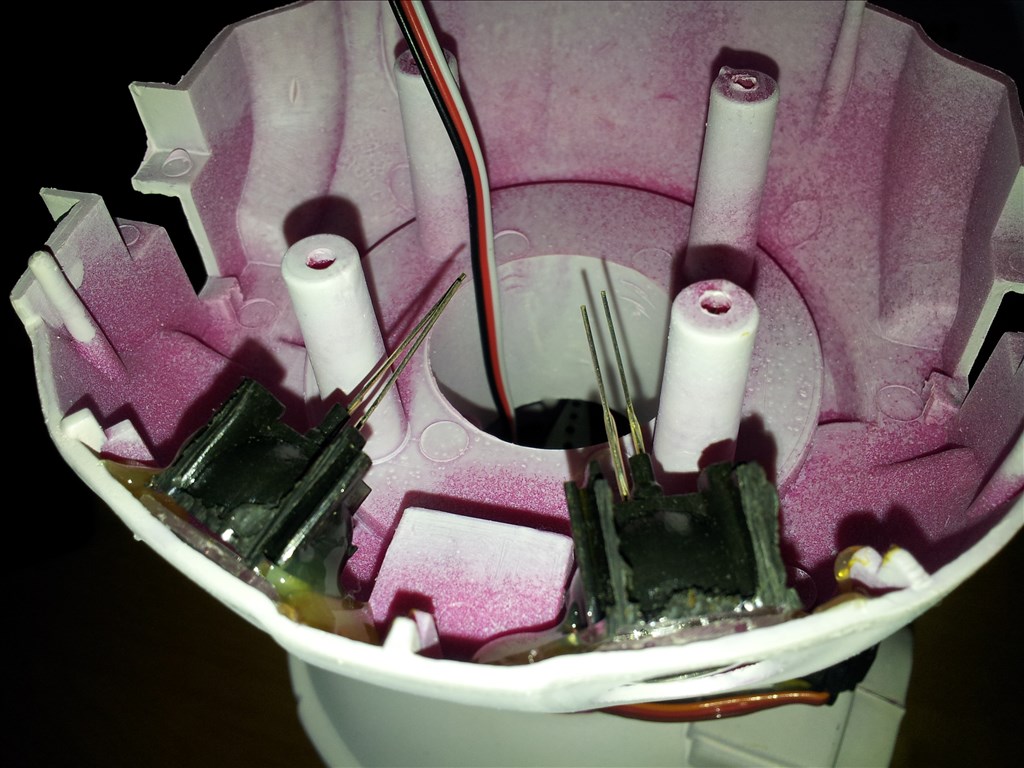
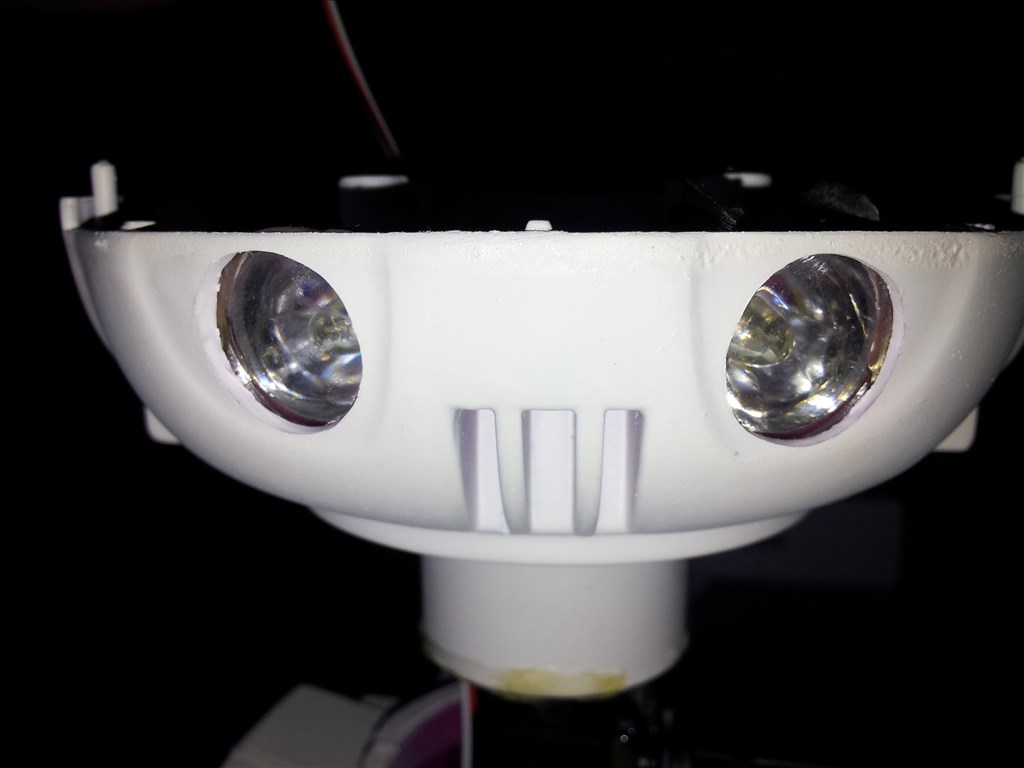
the camera is modified to be powered by USB and at least the head is moving
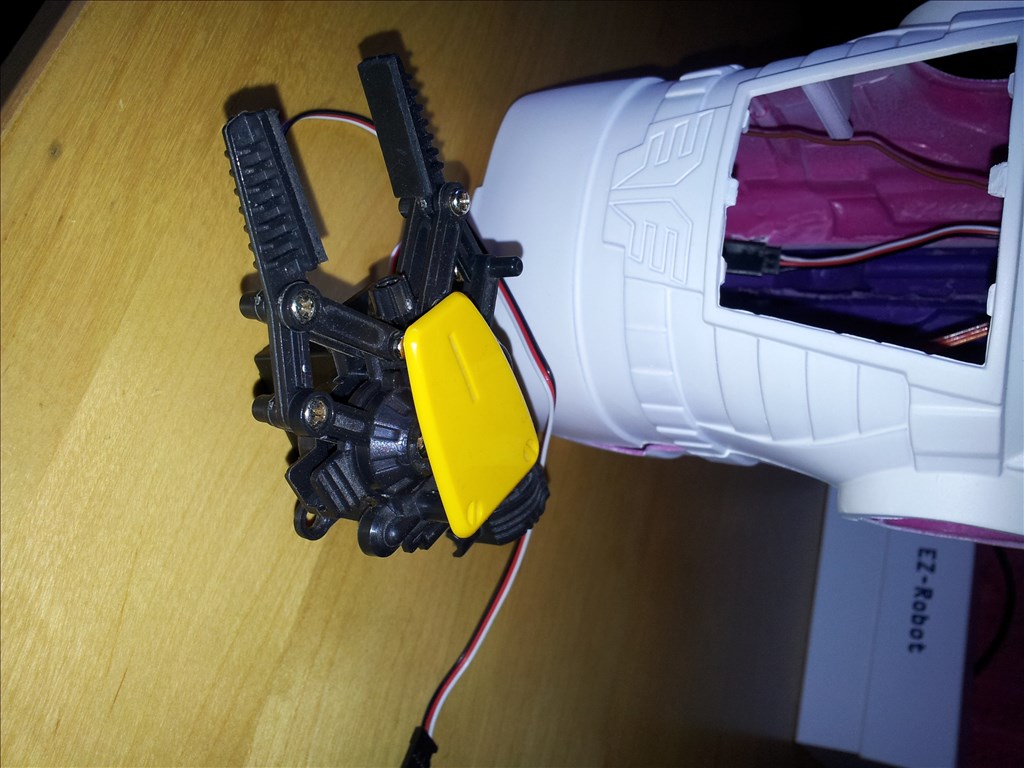
The hand is built out of a OWI-robot-arm and connected with a servo. Next step will be the arms. Until now I´m not sure which feet it will get.
Greetings from the bavarian-wood.
PS: sorry for my bad english tired
By HablijacK
— Last update

Discover more robots
DJ's Self Docking Robot
Synthiam ARC enables phone control and simple self-docking for Ohmnilabs telepresence robots using a Logitech camera...
Mereyes's Mereyes WALL-E
WallE replica using EZB v3 controller: wheel/arm/head servos, BlinkM eye, 2.4GHz camera, SparkFun MP3 trigger, 6V...
Tmesserschmidt's Meet Melvis: My Ultra Humanoid Robot
Melvis humanoid uses EZB for everything, Elvis-faced head, 3D-printed InMoov arms, planned Segway mobility and future...

Your Marvin robot looks awersome if you are still in the process of building Marvin keep up the awersome work


Here we go,
long time ago, in bavaria far far away ... Marvin has to wait for a long time, but now i can continue my work.
Shoulders were mounted provisorily to test the functionality and the look. A rover base completes the black and white look (looks like i have to raise the body a bit so that the proportion of the body and the rover fit each other)
The battery pack was mounted in the black jet-pack on the backside.
Here is a small video of his previous functions:
I love the Rover 5 base by DAGU
It gives it a awesome look.
That is a delightful robot. Keep up the good work.
:D