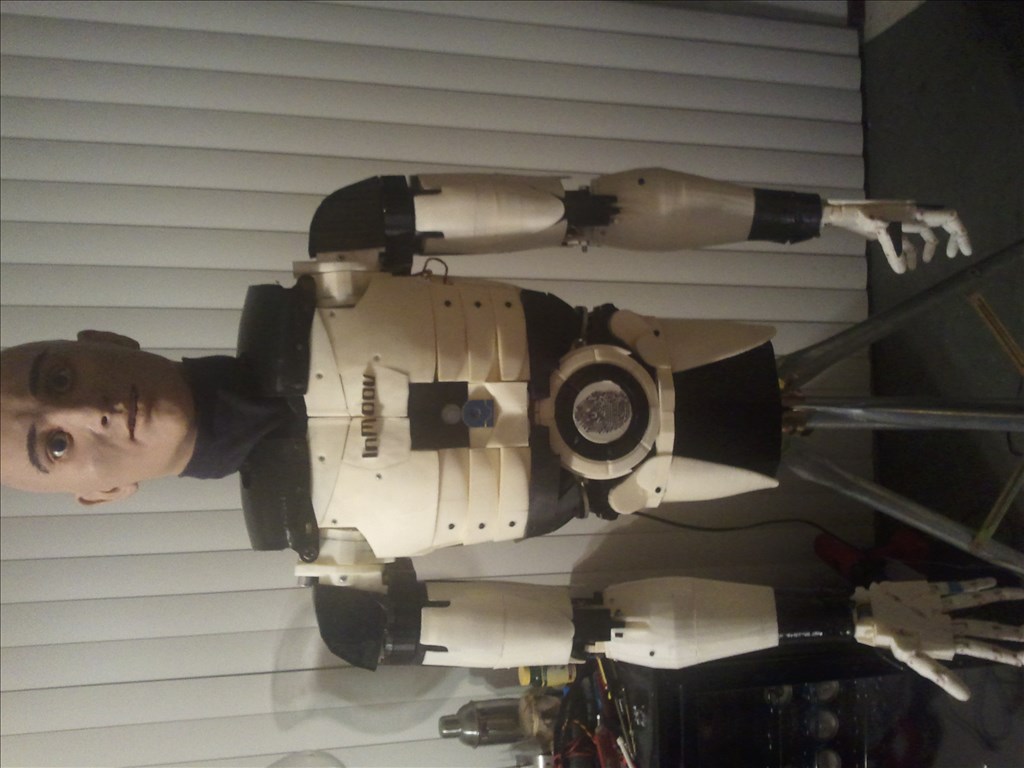
I'm finished building my Inmoov, Mo. Finely! Almost, waiting for a new EZB4 to power Inmoov's head. Still have lots more to add to him. I shortened the neck part to fit the big head on Inmoov. You can see the difference in the second video.
By Redzone
— Last update
Discover more robots
Ezang's My New And Improved Talk Servo
Enhanced ARC Talk Servo with Arduino Arc software for improved servo control and seamless Arduino integration
Buratino's Buratino - Humanoid Animatronic
Buratino 50x50cm 3D-printed humanoid with 23 DOF, heavy-torque servos, EZB camera motion tracking, speech recognition...
Cirkeith's Upgraded Wall-E
WALL-E inspired mobile robot controlled by a wireless Xbox 360 controller, upgradeable with EZ-B kit and embedded...

Removed link
merne, Looking great. That is quite an accomplishment to build that robot! I know there are many pcs to print, build, and tweak on assembly. The shorter neck makes the head look better. Have you thought about adding some type of black trim turtleneck type collar to blend the head to the body? Looking forward to any new videos. Steve S
@Steve S. Thanks it take some work. I like your idea so I tried it and I like the way it comes out thank you Merne
merne, The new pic looks great! Great blend.
You have built an amazing robot. Keep up the great work and keep exploring! I have many trials and experimenting with my bots. Steve S