Any chance of that happening?
Looks like dependencies on .net are messing up for linux dev.
just wondering if an open source option will be available
 Ultrasonic Collision Detection
— Stops robot movement (no steering) when an EZB-connected ultrasonic sensor detects an object within a set range; integrates with scripting and paused polling.
Try it →
Any chance of that happening?
Looks like dependencies on .net are messing up for linux dev.
just wondering if an open source option will be available

And?...... The world is waiting
Sorry
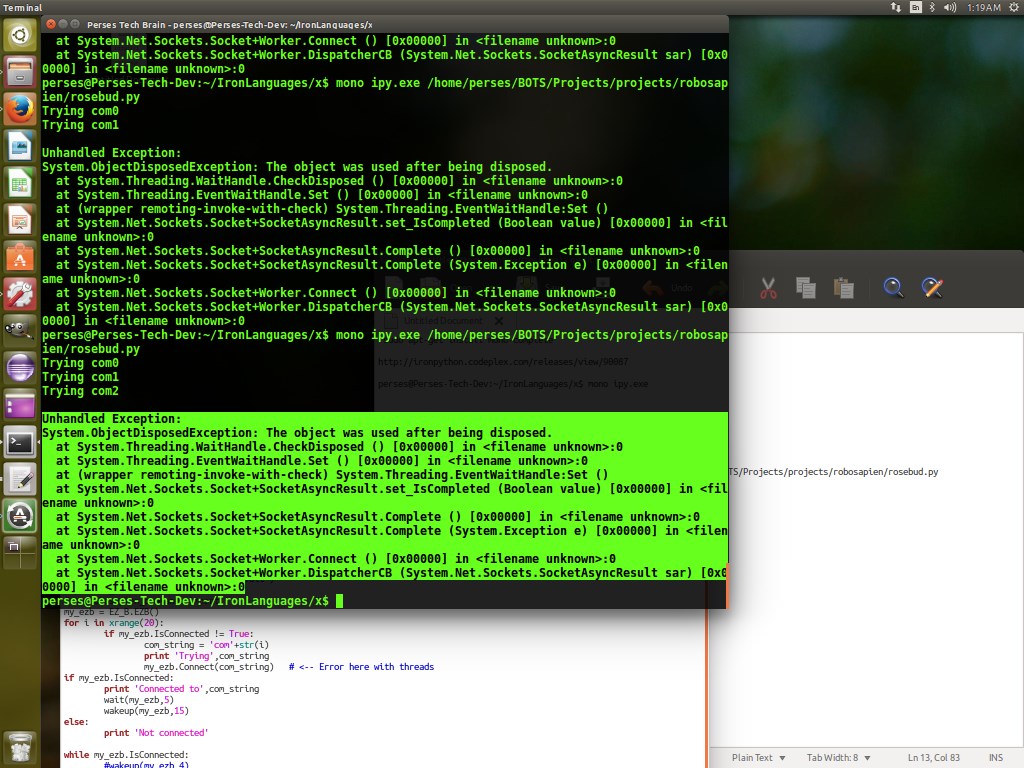
Looks like its not threading correctly
I thread and program always correctly I would need to see your code to better understand the error. Or at least a proper stack trace. Thanks!
I'm using the robosapien code
https://synthiam.com/Community/Questions/3275
Robosapien doesn't work on ezb v4
im running v3
trying alternative connect methods . might need to think outside the box with this.
is ezb communication anything like arduino type communication ?
also, i don't have a robosapien. just using his script to establish a connection. its in the above screen shot below the terminal window.
Whats different between v3 and 4 that doesn't let it function
Also, is the baud rate for the v3, 9600 bps or something else