
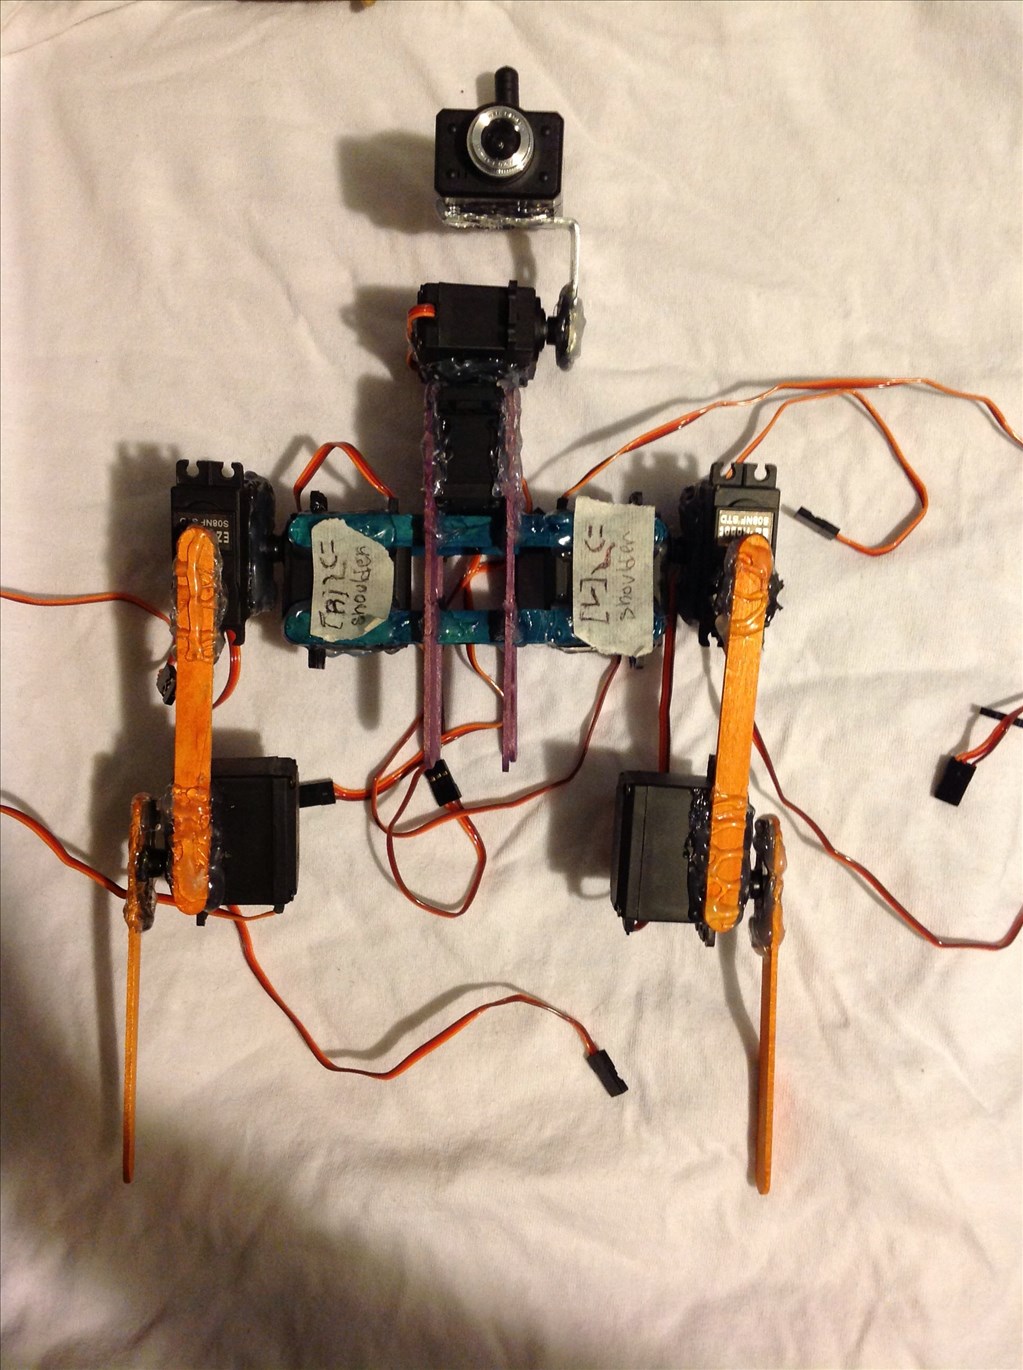
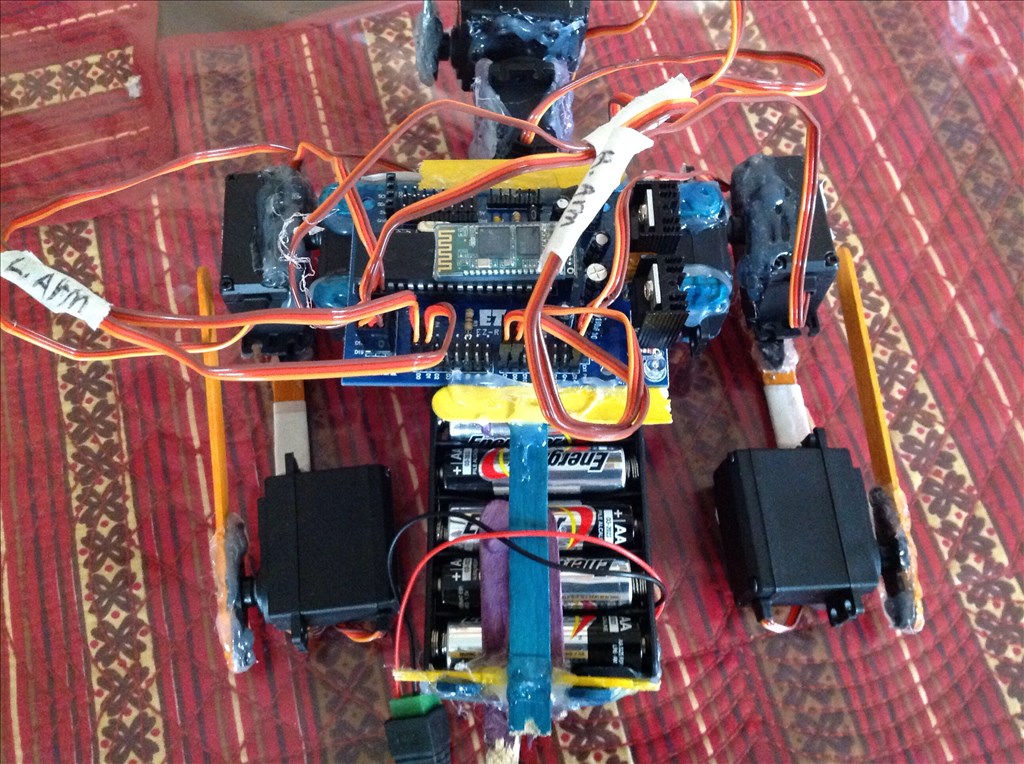
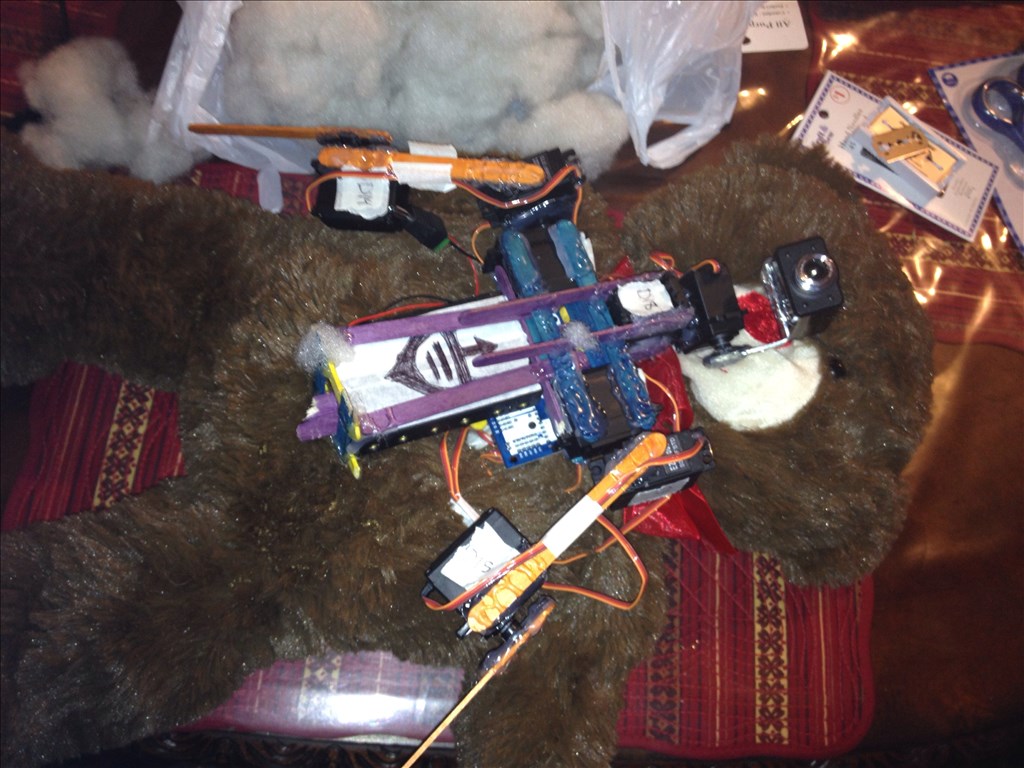
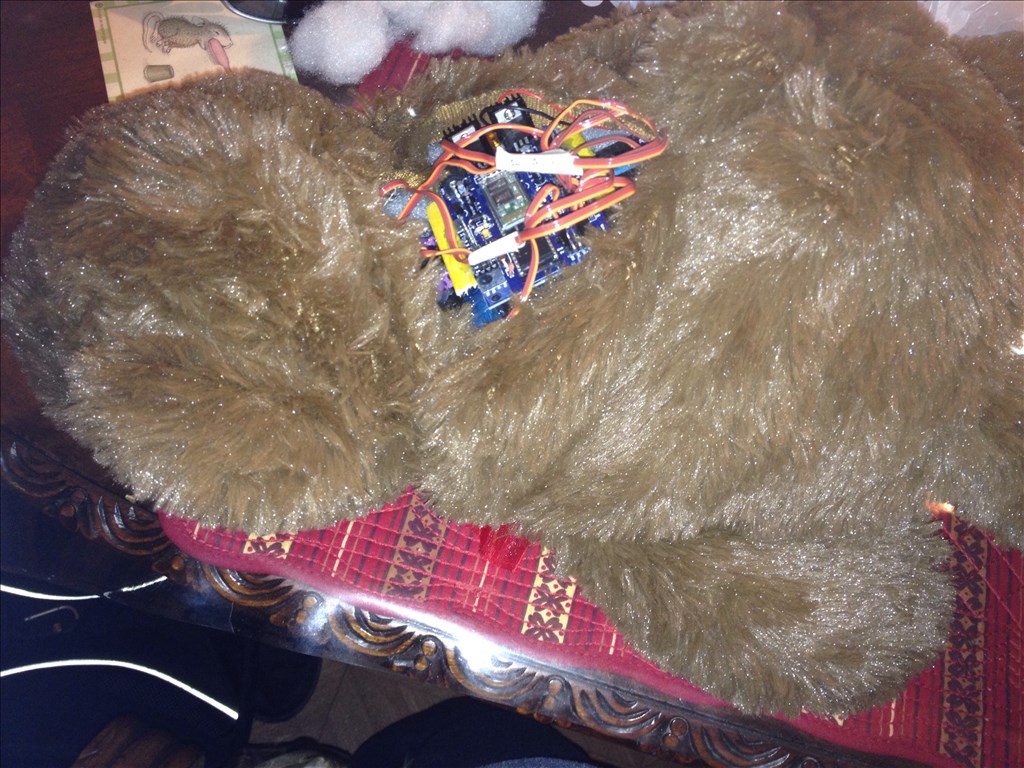
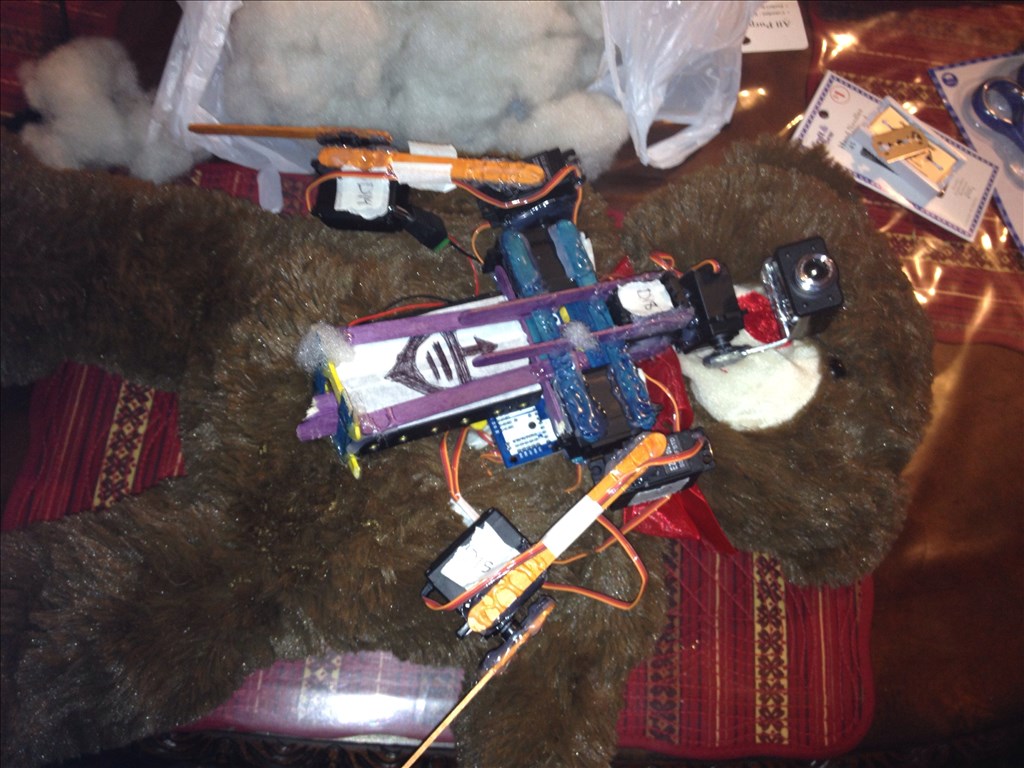
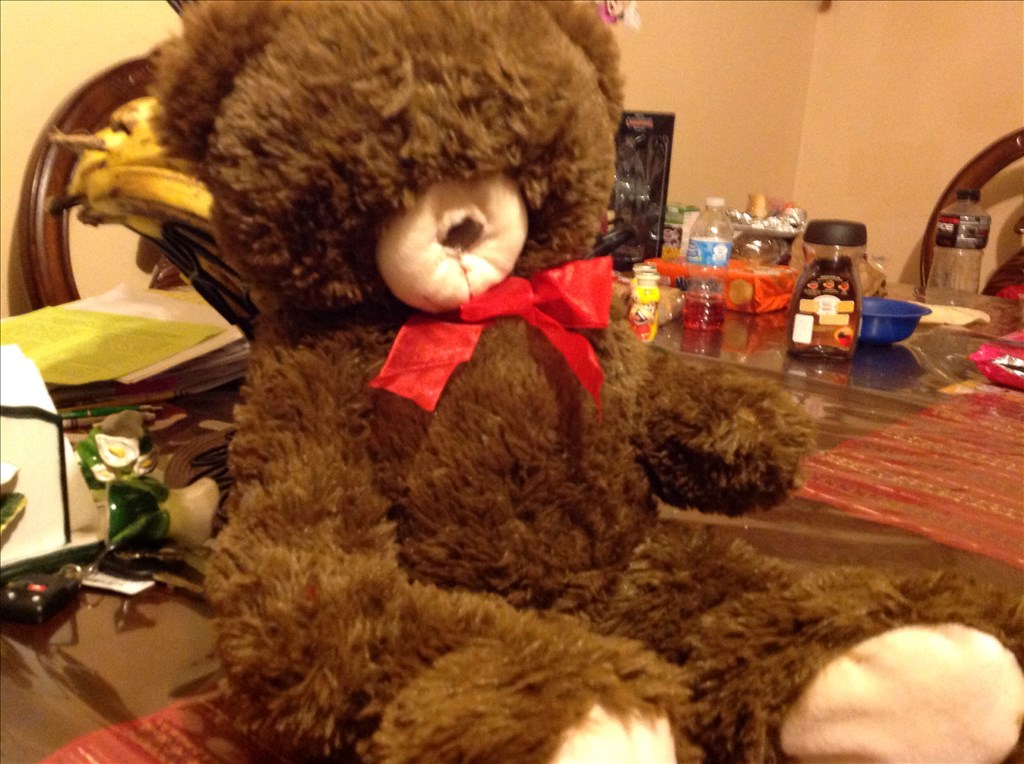
A while back I was working on a humanoid robot but I only have worked from the waist up. The Bluetooth was not working with my old computer, and I just bought a new laptop not too long ago, and now am able to work on my robot these are some pictures from my Teddy project, I got the inspiration from the movie artificial intelligence (A.I). Since we are close to valentines day there are plenty of bears to choose from. If you guys have any feed back please let me know or if there is something you would change from this. I will be more than happy to read your ideas and thoughts. I tried adding a YouTube video but there was an error downloading it.
By A.Bautista
— Last update

Discover more robots
Steve1dh's Test-Practice Bot
Test robot on Steel Tec tray base with EZ-B, ping and IR sensors, pan-tilt camera, joystick control, LED and servo lift...
Bmcnamee1's Extending Jd
3D-printed male/female servo spacers extend JD by 2.75 inches, increasing leg reach and dramatically boosting speed with...
Ezang's New Robot Head Video Project 6/15/2021
Robot head teardown and component breakdown from 6/15/2021, revealing build details and assembly insights

Yes justinratliff, it was a nightmare to stuff everything in haha. Specially to have the camera right where the nose is. And I used a 500ml water bottle I put lots of tape and glue to make it as steady possible. I cut the bottle in half and glued the camera in the bottle so the lense would see trough the hole on the top of the bottle, then when I put in that part into the bear I wraped a couple of rubber bands so that the skin of the bear and the top of the bottle would hold together while I glued the bottle and the skin together with hot glue
Thank you antron
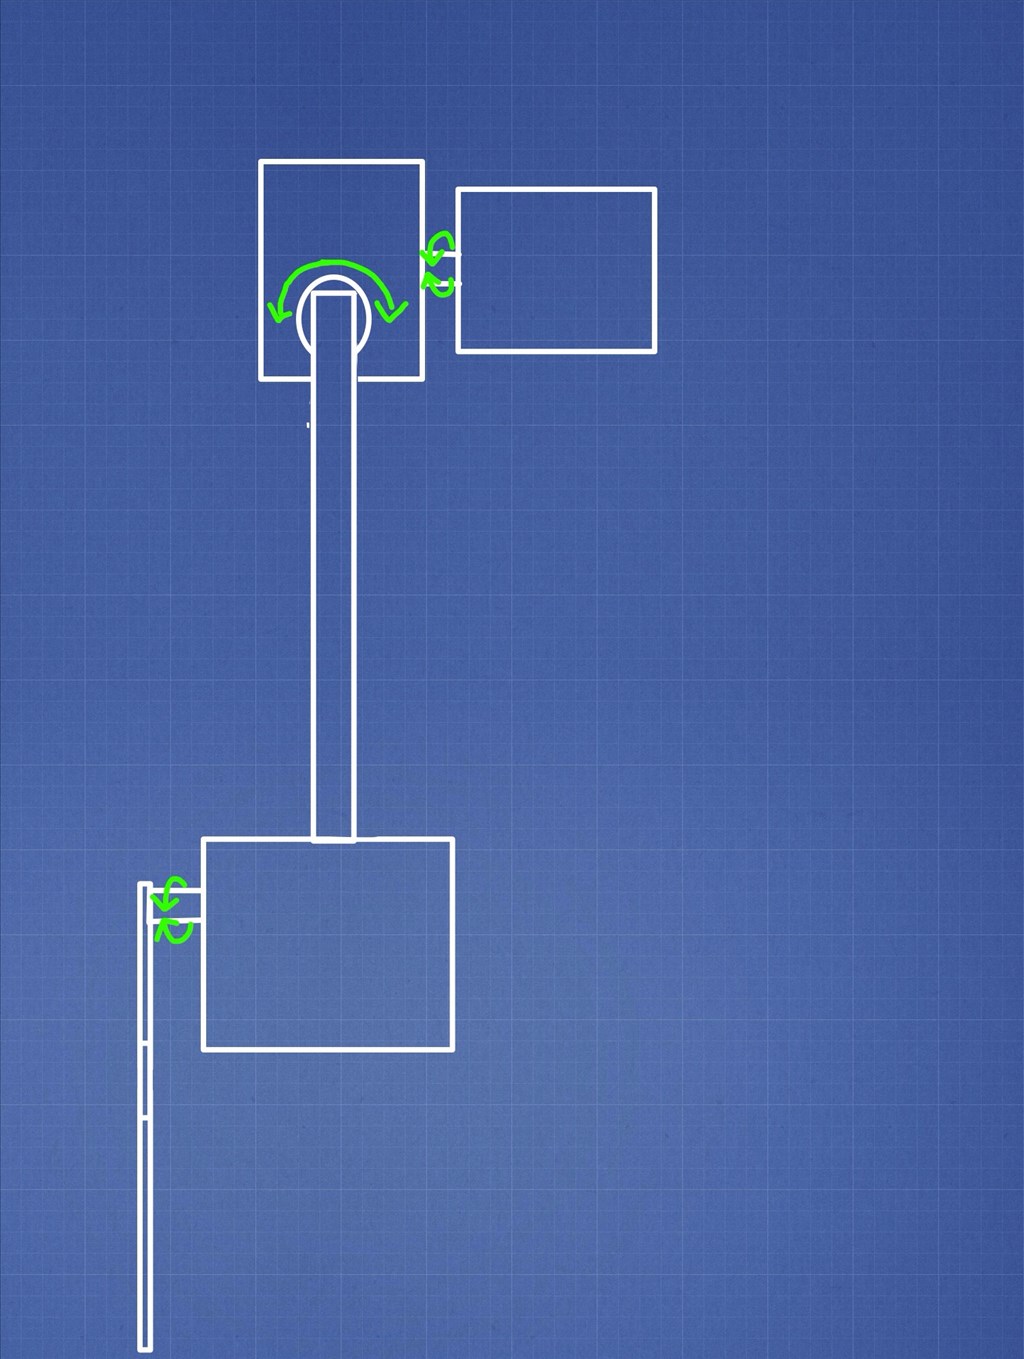
I keep looking over the frame....I just noticed each arm has 3dof. that's awesome. the arm can move up and down, in and out and wave. very well done.
any ideas on getting the bear either walking or moving on hand and feet?
im totally doing this to a "baby Chewbacca" i have.
ill post a pick tonight.
Yes, it does here is a bad drawing of the rotation points on his right arm
And for walking I do have an idea, what I am thinking is copy the the arms and switch the way the elbow moves to the proper way a knee would move, but again I don't know if it will stable this way. Am going to buy some servos and test it out. And I'll like to check out your baby chewbacca let me know wen its up
The Chewbacca is too small. I'll have to purchase the ted doll.
You might be able to use the micro servos if its small