 Thanx!
Troy
USA
Asked
— Edited

It's.It's.Omg It's A Cylon
It's now only a matter of time before they enslave us. Thanx!
Thanx!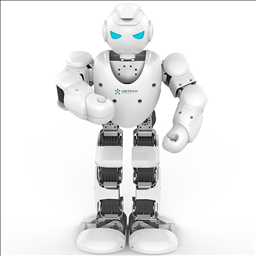 UBTECH Alpha Servos UBT-12HC
— Control UBTECH Alpha UBT-12HC smart servos via ARC using EZ-B v4/IoTiny UART, assign virtual ports, set baud, custom bits and position mapping.
Try it →
Thanx!

My guess is the use of gyro's. I suspect one in each side of the backpack, and one in the center, maybe in the head. The speed of the gyro's can be manipulated to adjust for angular compensation.
The use of real-time momentum calculations are visible in both walking and standing up from lying forward. For that, they'd be using a combination of gyroscope (for force) and accelerometer (for angles)
It appears that the hips are fixed around a knob rather than a straight rod extending out...I feel like it would be able to balance steadily on one foot or even try to ride a airhweel q6 hahaha