

https://www.indiegogo.com/robotdragonfly Looks like something that ARC should interface with.
Asked
— Edited
4 Participants
 Robotis Openmanipulatorx
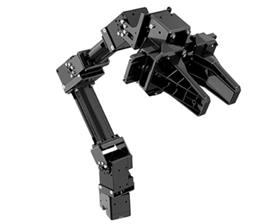
— Inverse kinematics for Robotis OpenManipulatorX: compute joint angles and MoveTo 3D (cm) positions, supports camera-to-CM mapping for pick-and-place.
Try it →
https://www.indiegogo.com/robotdragonfly Looks like something that ARC should interface with.

@robotmaker , a fitting name indeed. I would love to see a short YT vid with all your bots.