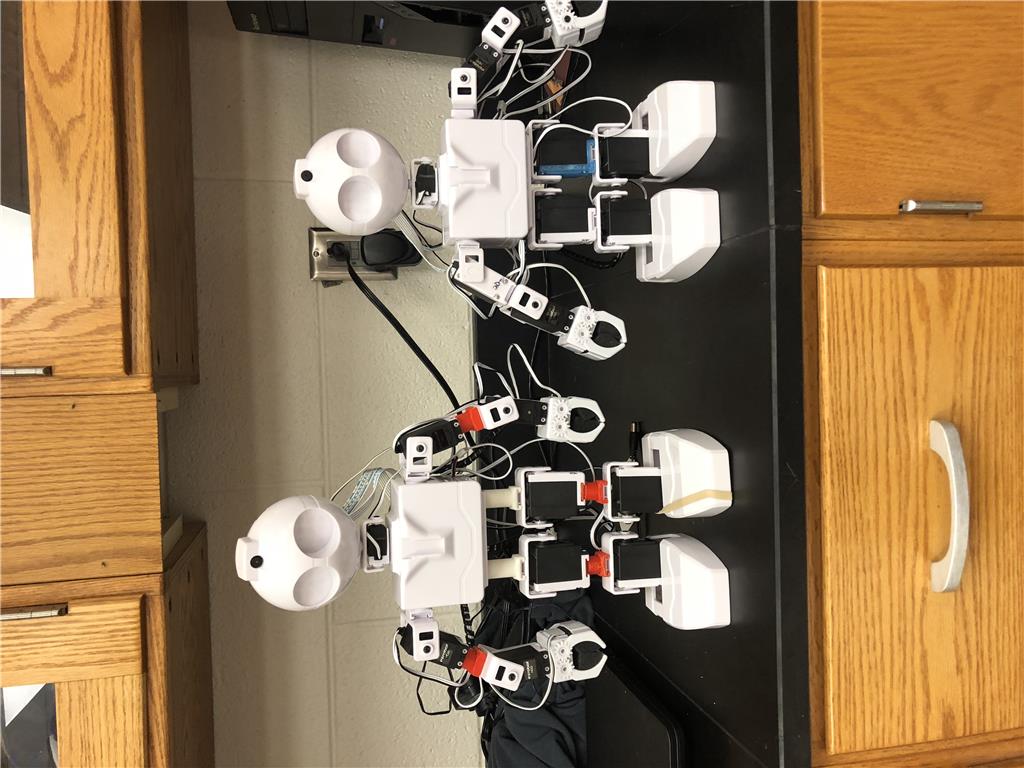
We have designed and 3D printed pieces with both a male and female parts, that connects in between the servos to make JD larger by 2.75 inches. This has also increased JD's speed tremendously because it takes longer steps.
By bmcnamee1
— Last update

Discover more robots
Jstarne1's Meet Dusty , Modded Omnibot 4 Home Security Cam,...
Dusty omnibot torso: vacuum and silent sweep modes, germicidal bulbs, multi-stage carbon/foam filters, pan-tilt camera,...
Cardboardhacker's Rc Car Ez-Fied
Modify RC truck to run dual DC motors with Sabertooth 2x12 and EZ-B V3, using gearboxes and standard servo steering...
Gwen4156's The G-Bot (Gwen's B9 Robot Project) Gets His...
G-Bot outdoor test: handling lag and ramping issues, tips to use wireless controller and prevent tread snags, successful...

Cool idea @bmcnamee1 !
I look forward to seeing some footage
Ok, so no one is going to make the obvious jokes?
Ooooooh - I'm not going there, zap! Haha
That's a good idea extending jd. Smart idea!
any chance you post the stl files ?
love to see the extended robot in action.
This is something that I have been meaning to print. I might remake them so they're wider and fill in the gap more for aesthetic purposes.
@dj
is there a video of jd faster walk ?
I haven't made it yet, but I can see how it would be faster. He might have trouble getting up from the front if his arms aren't extended, though. But it'll be worth the test.
@dj
what about the adaptive walke like nao robot ?
ad rotation on the arms turnble grippers and longer , extra lever servo legs .
https://www.youtube.com/watch?v=OBGHU-e1kc0