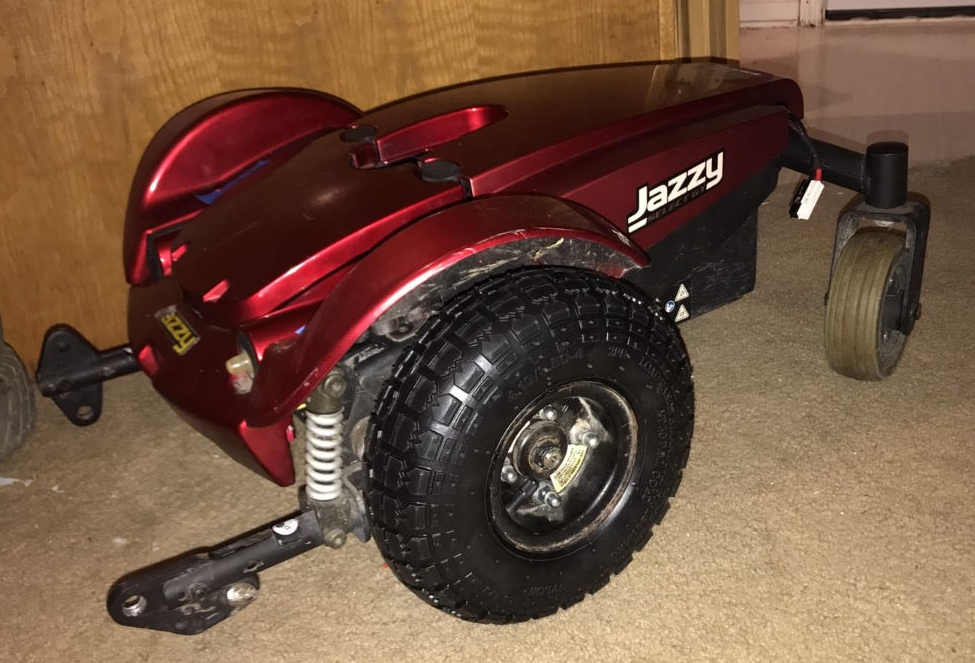
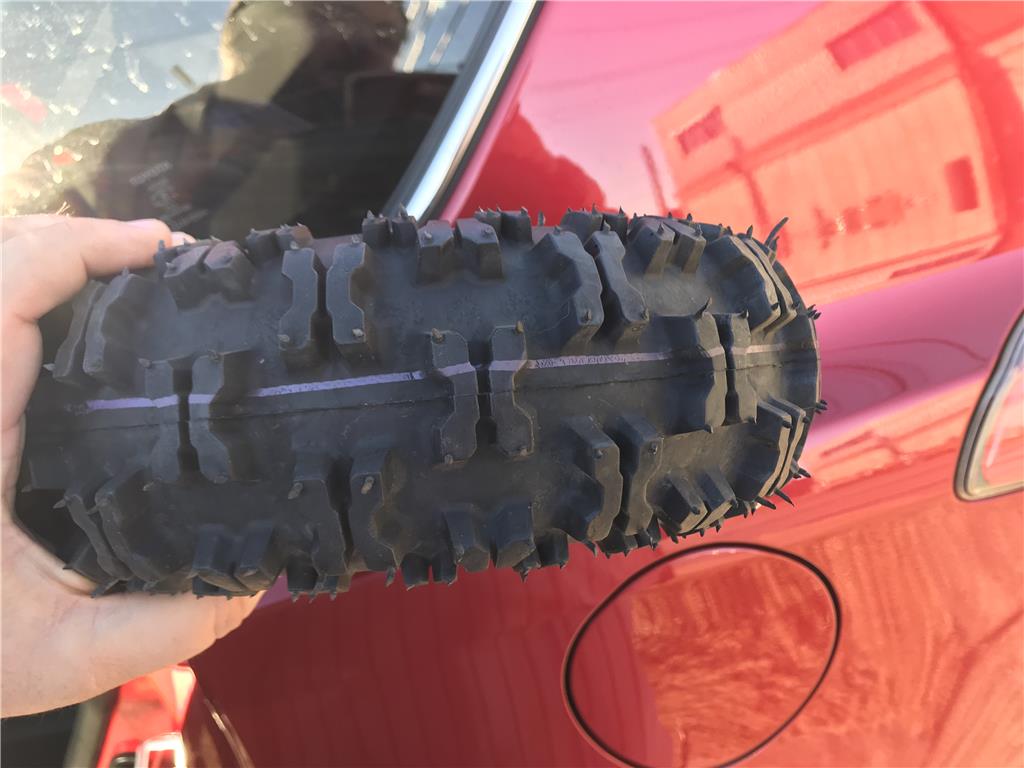
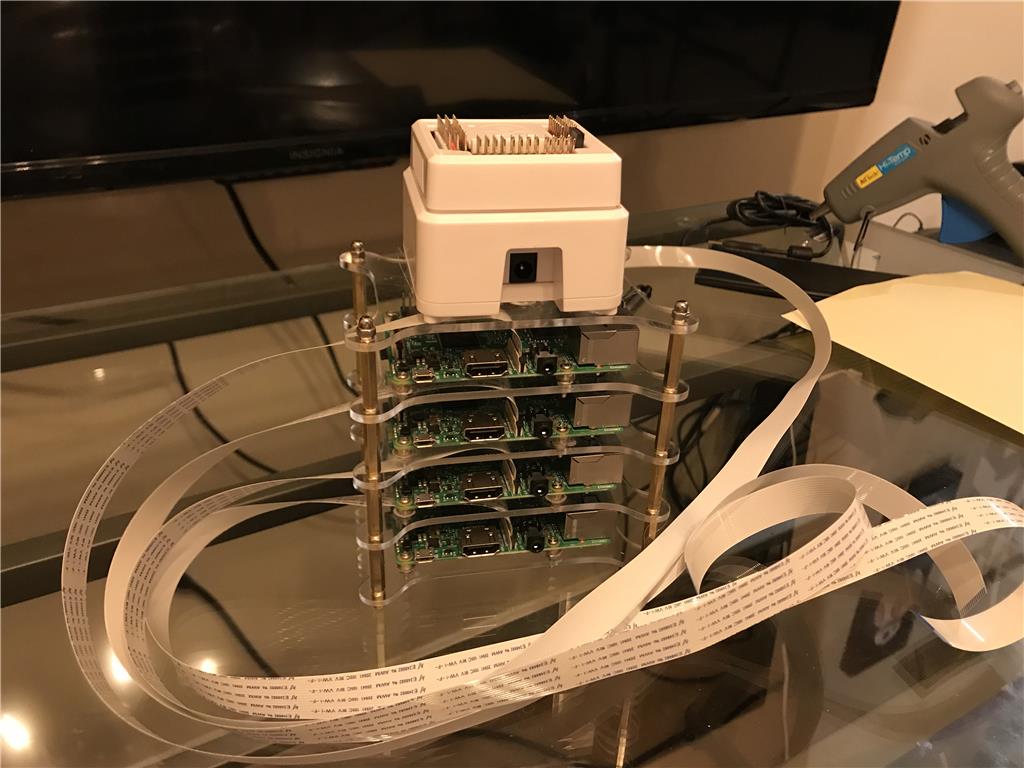
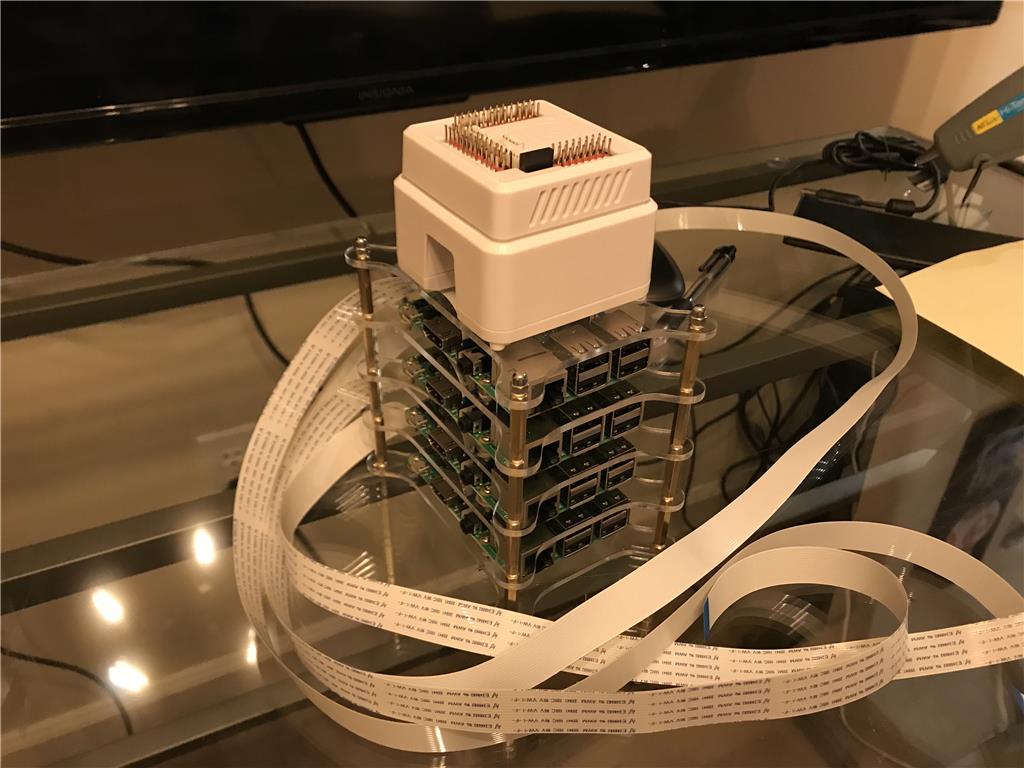
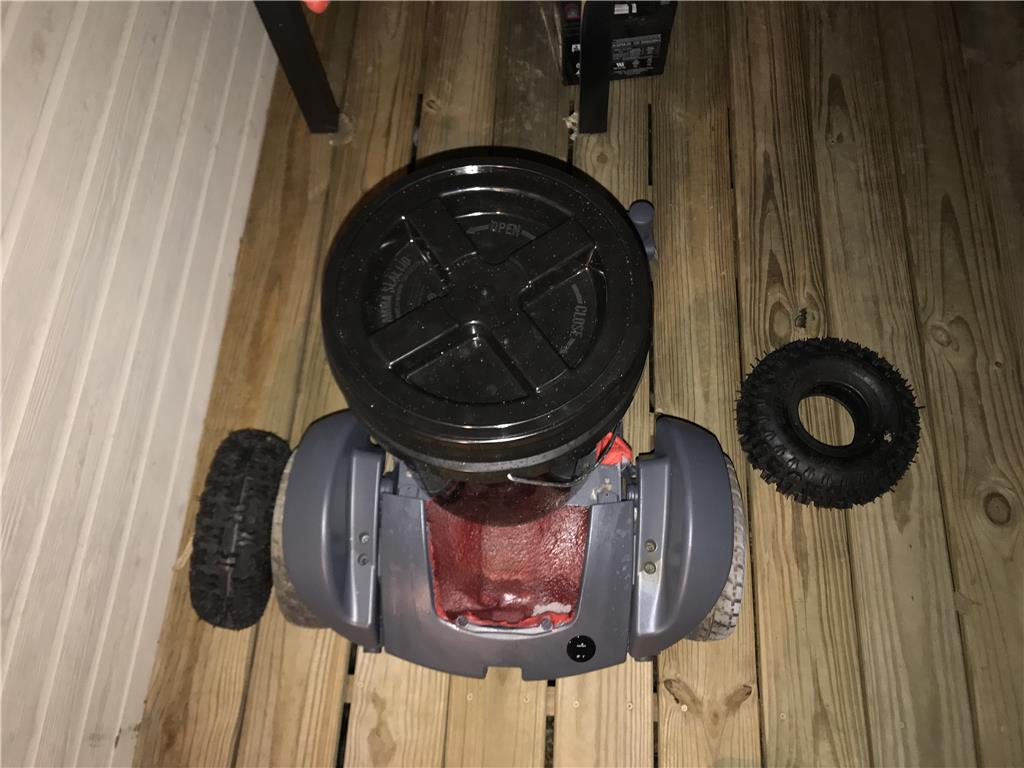
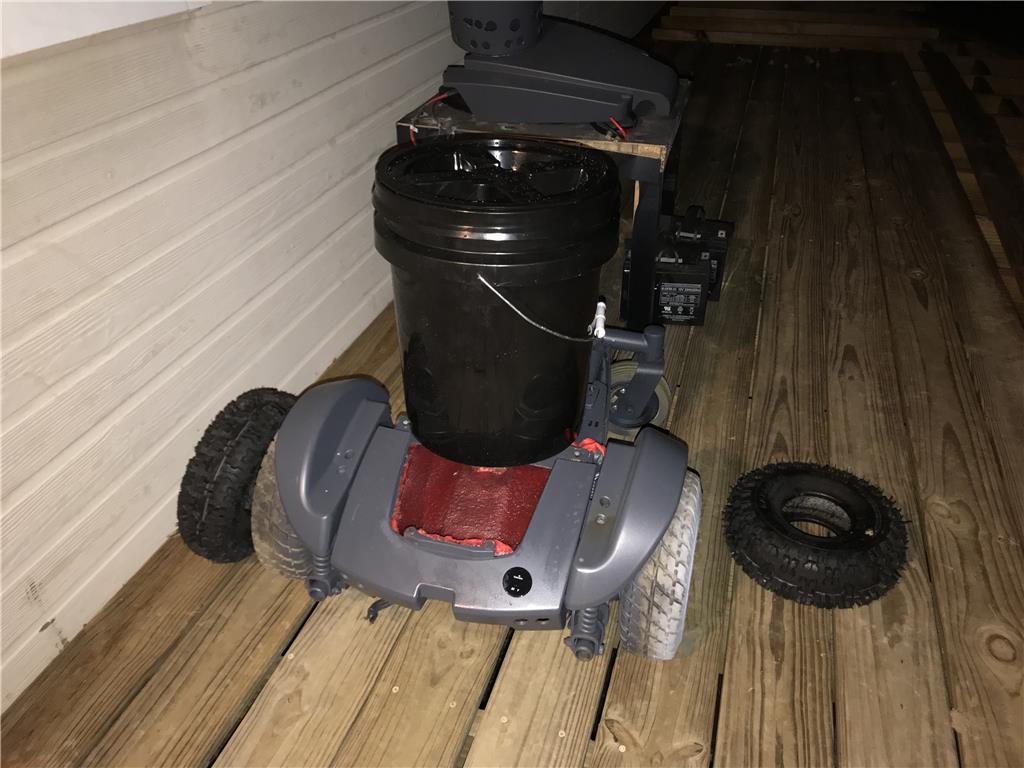
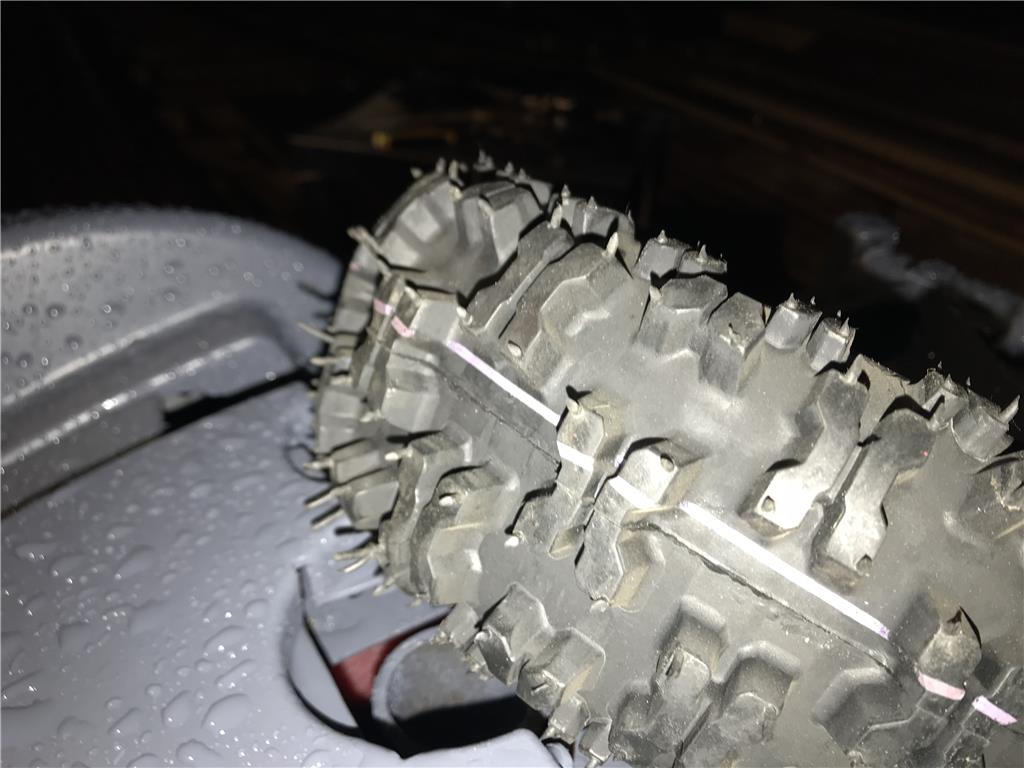
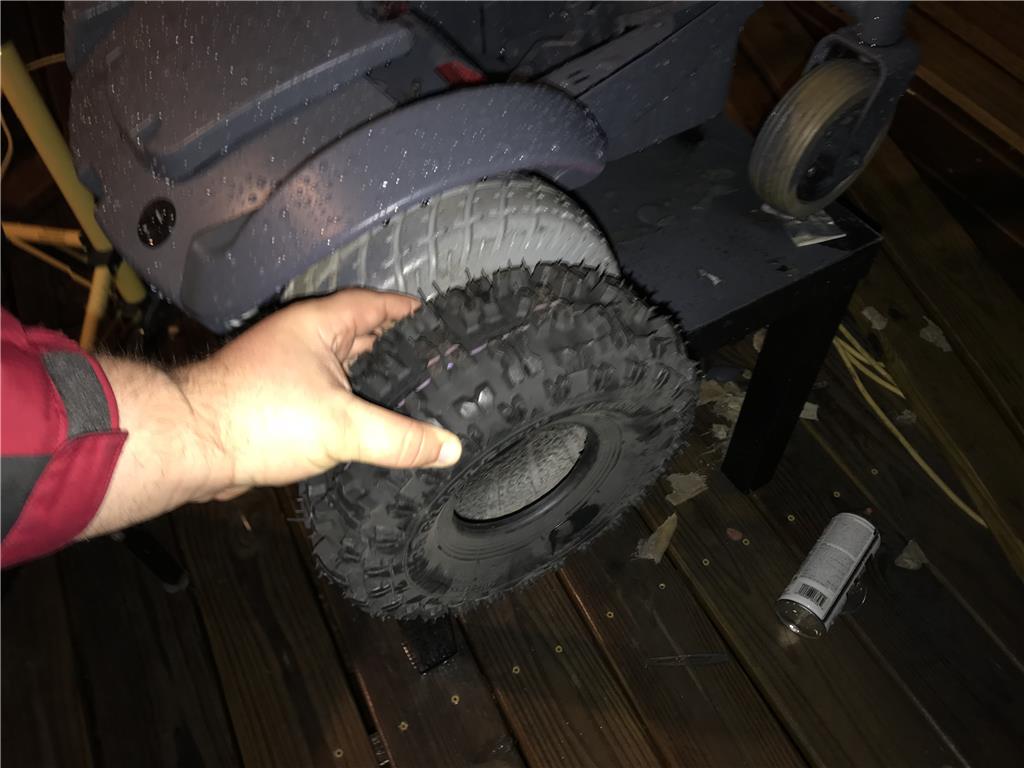
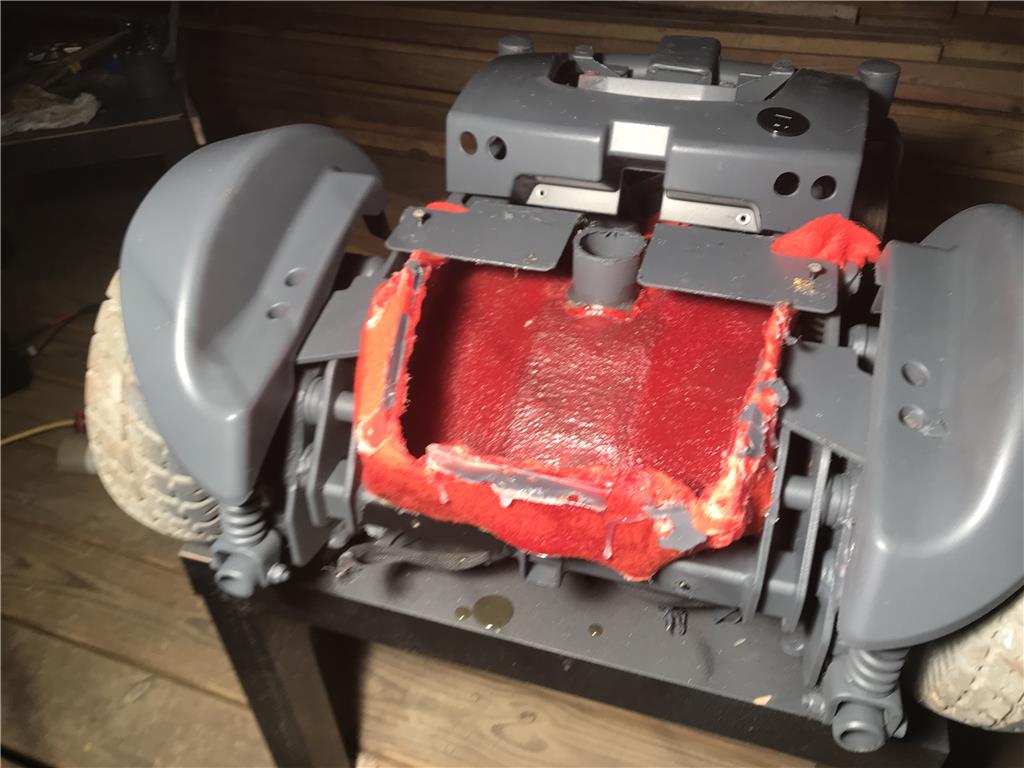
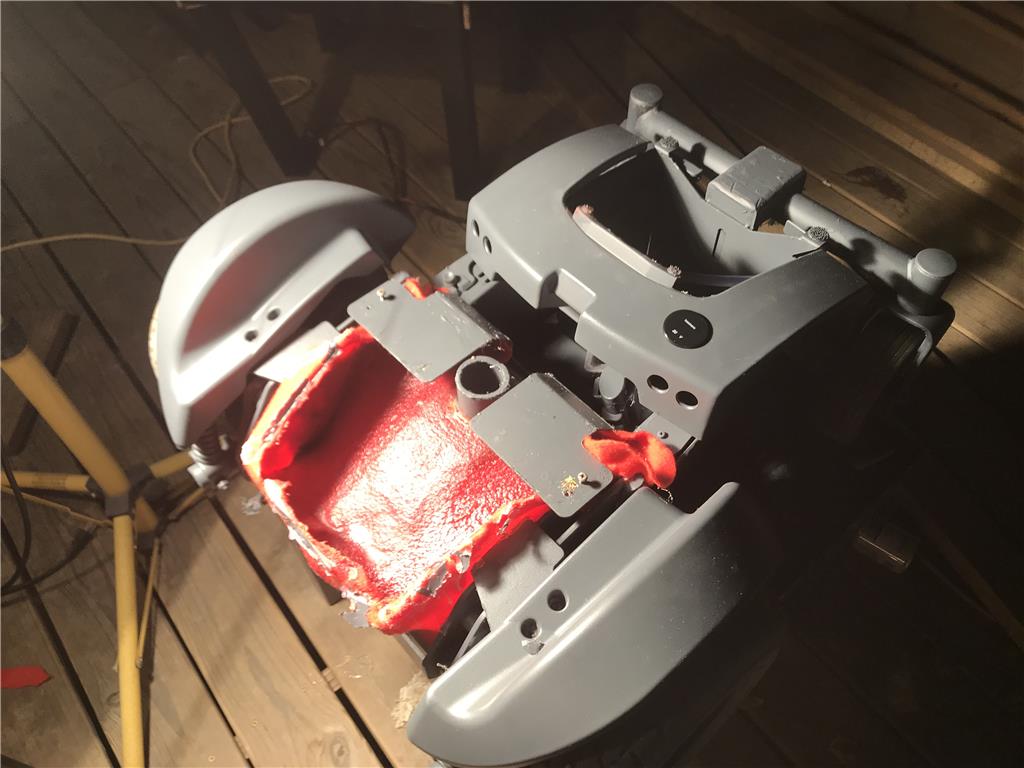
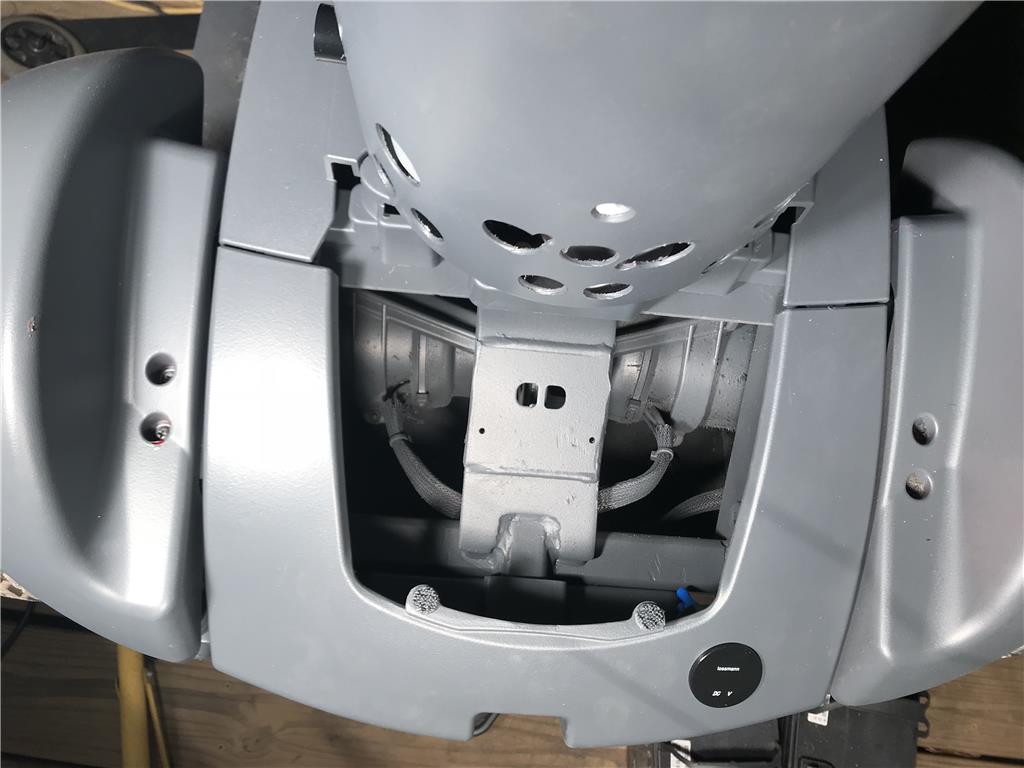
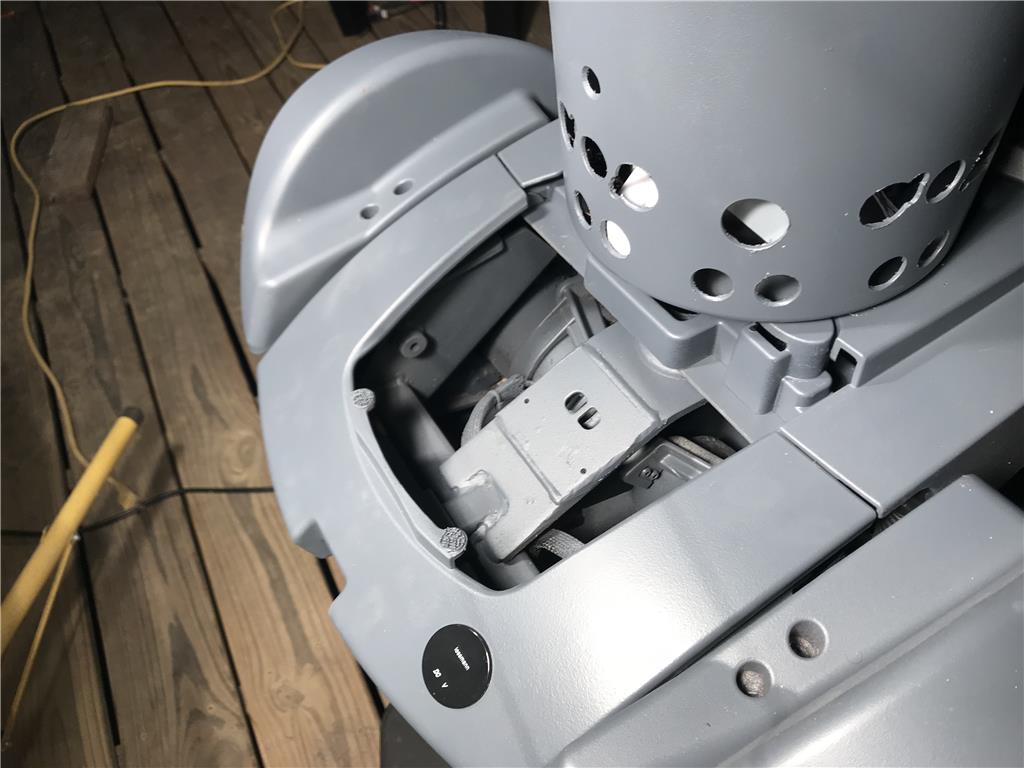
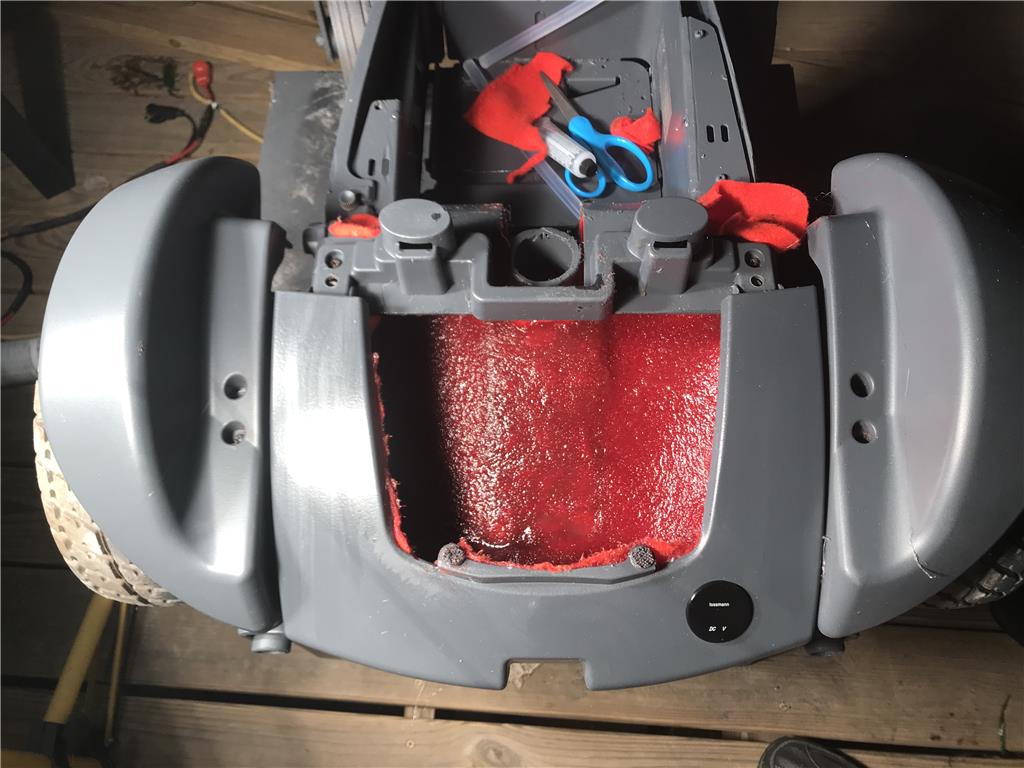
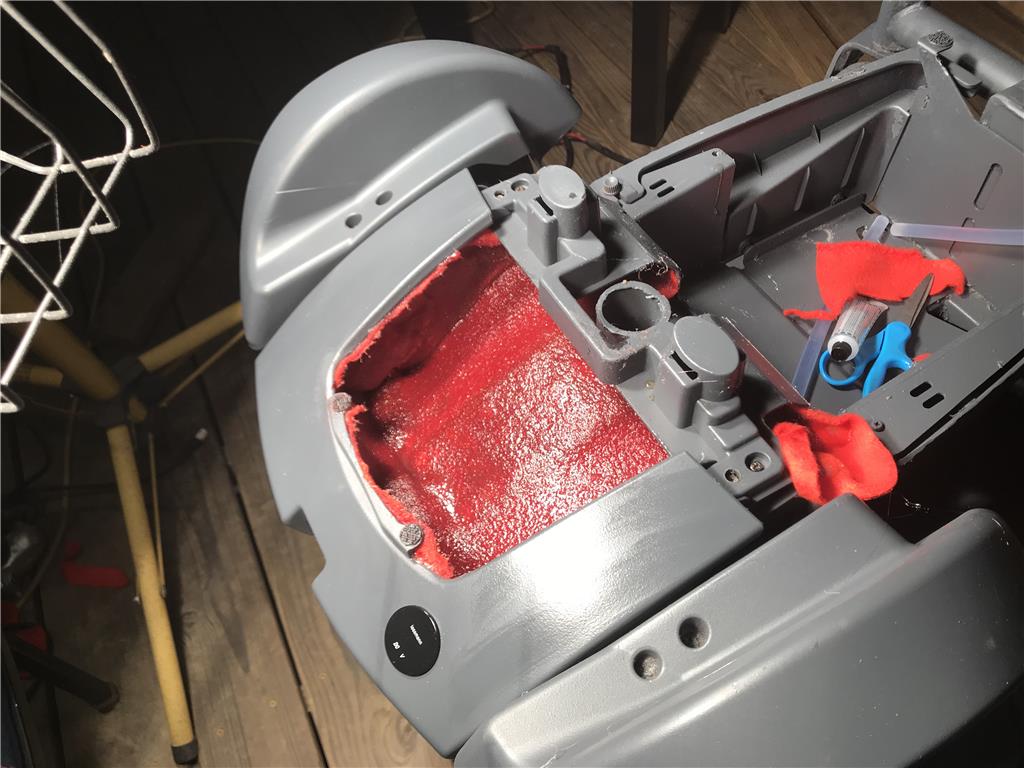
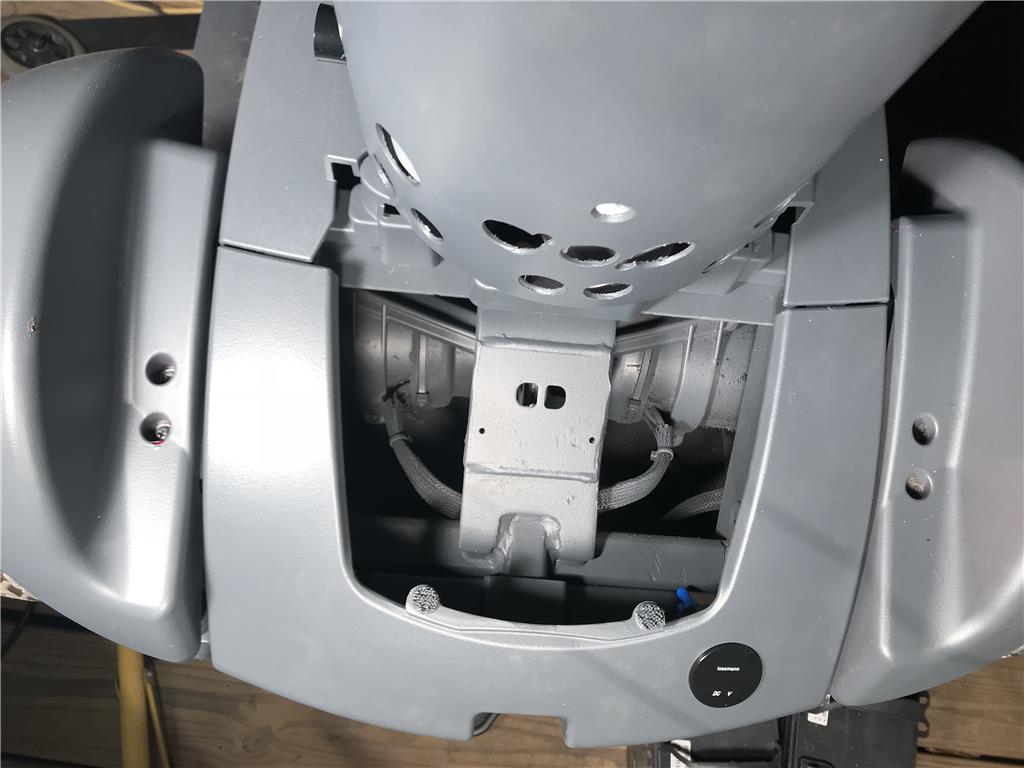
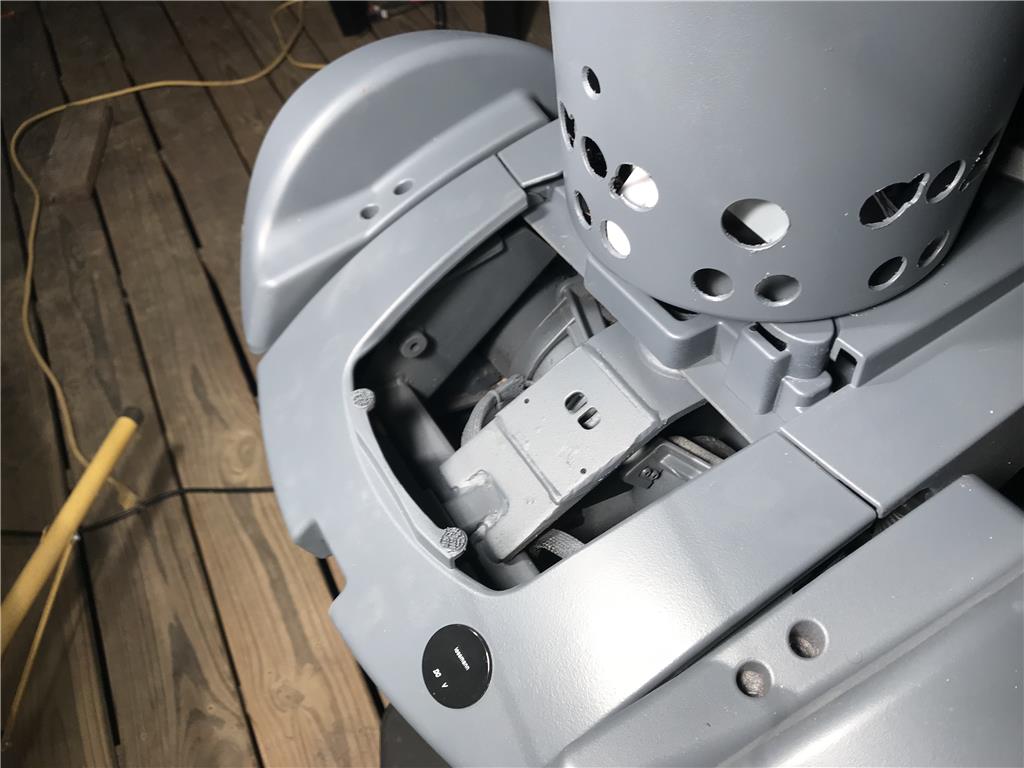
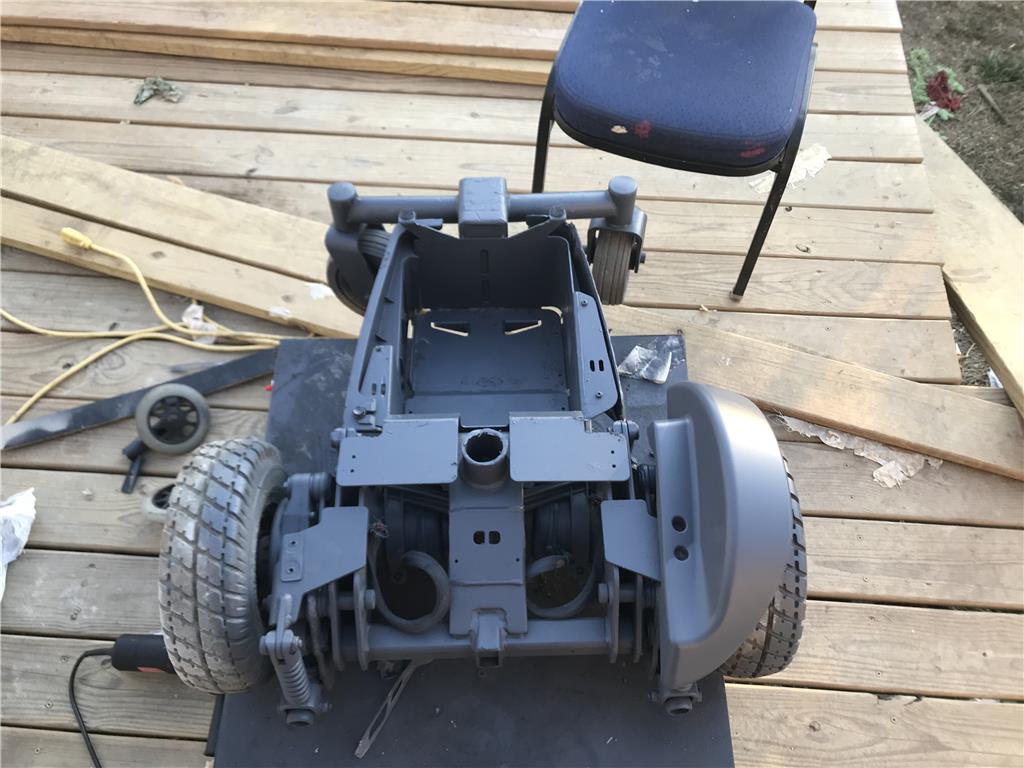
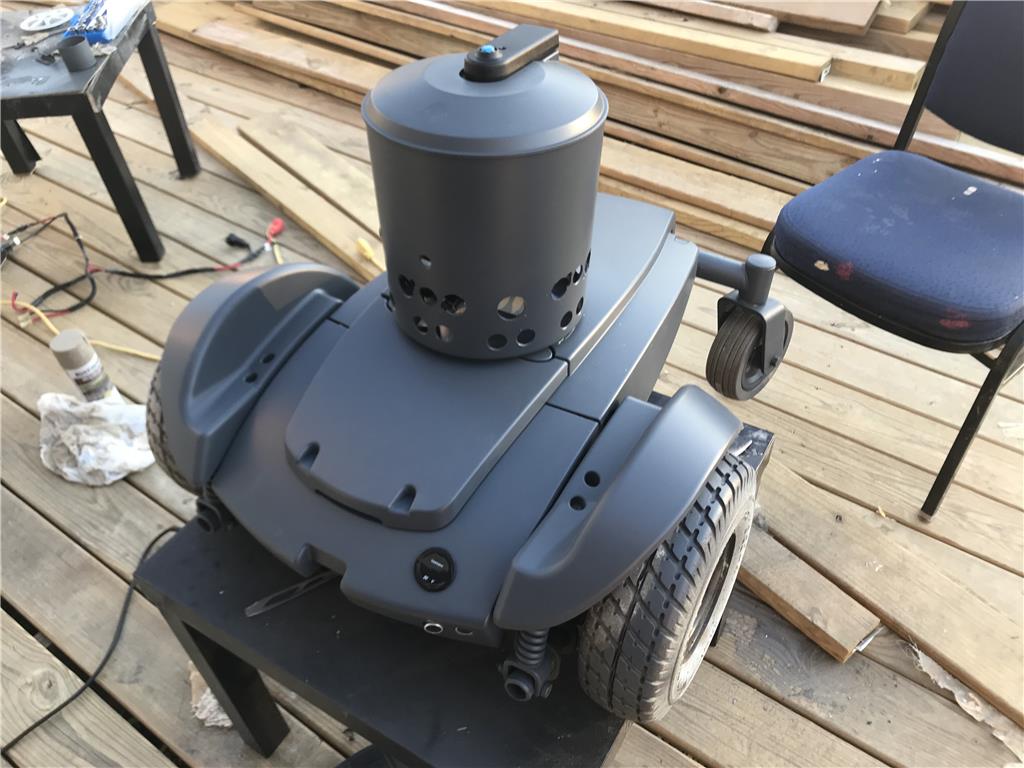
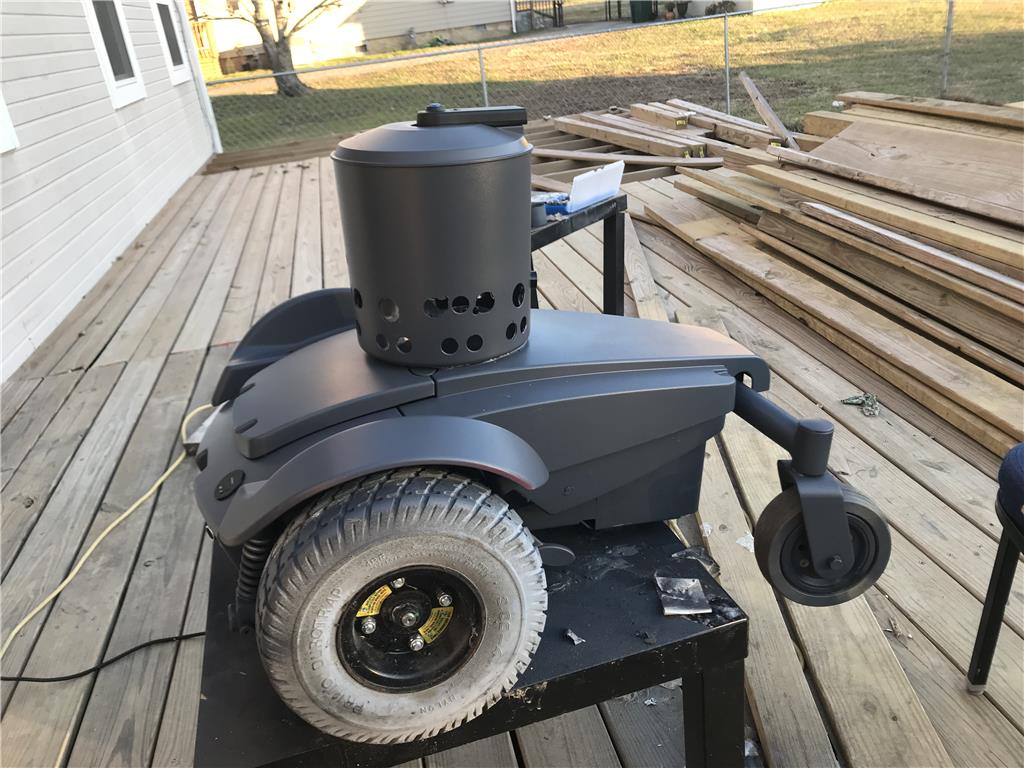
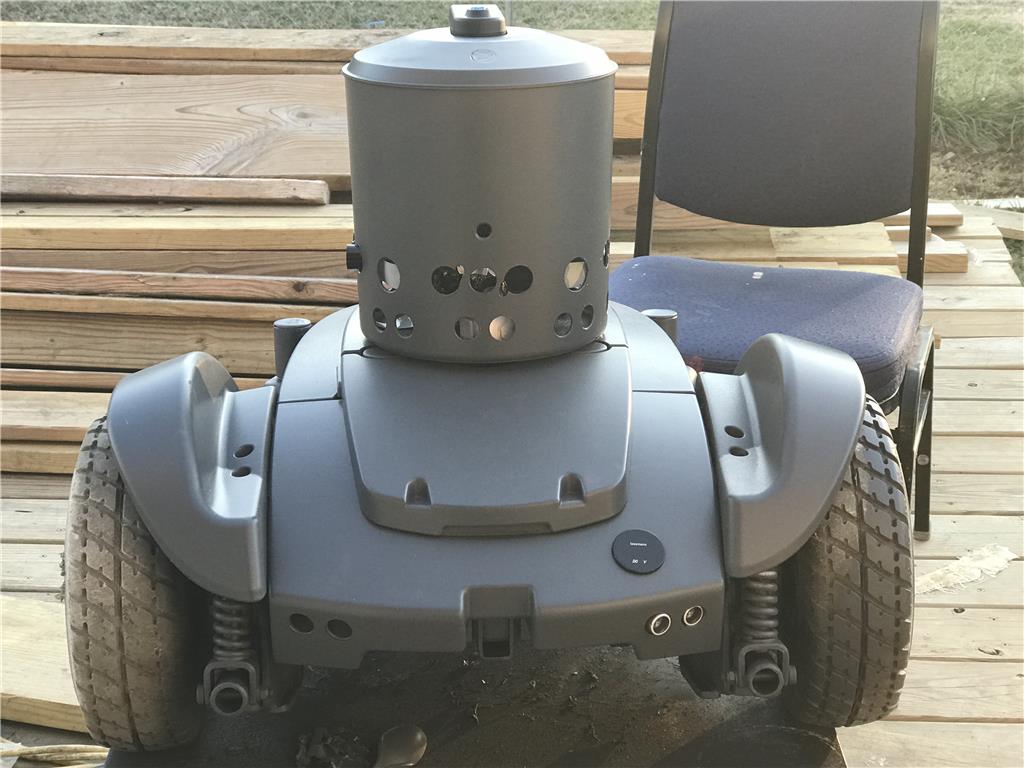
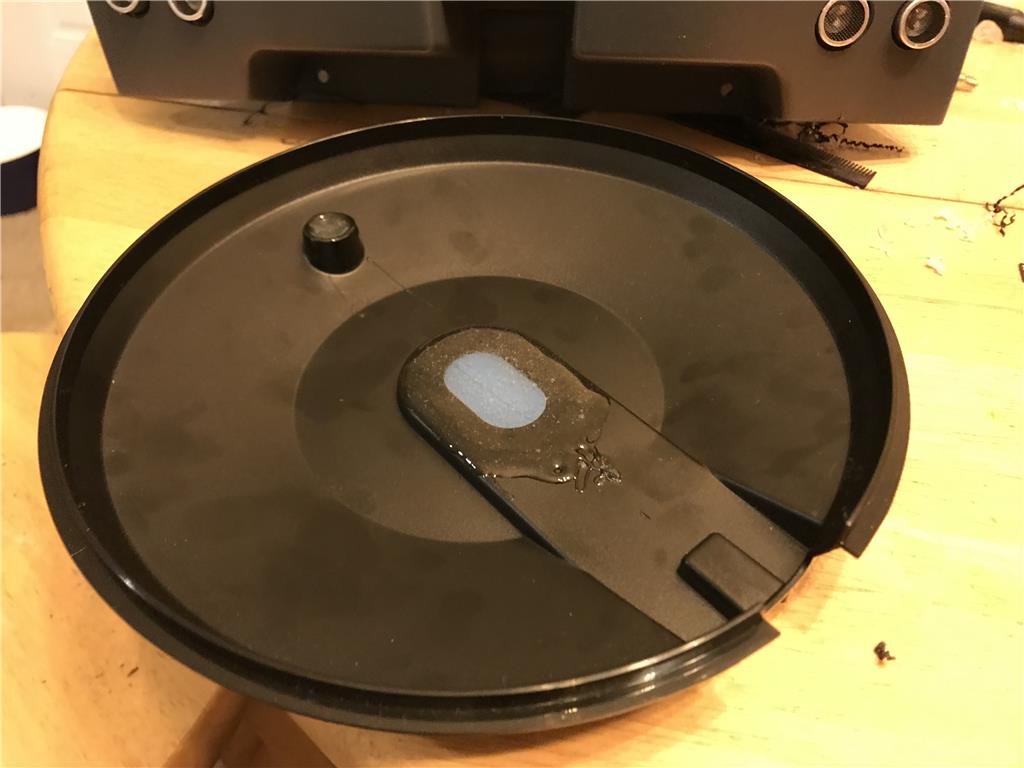
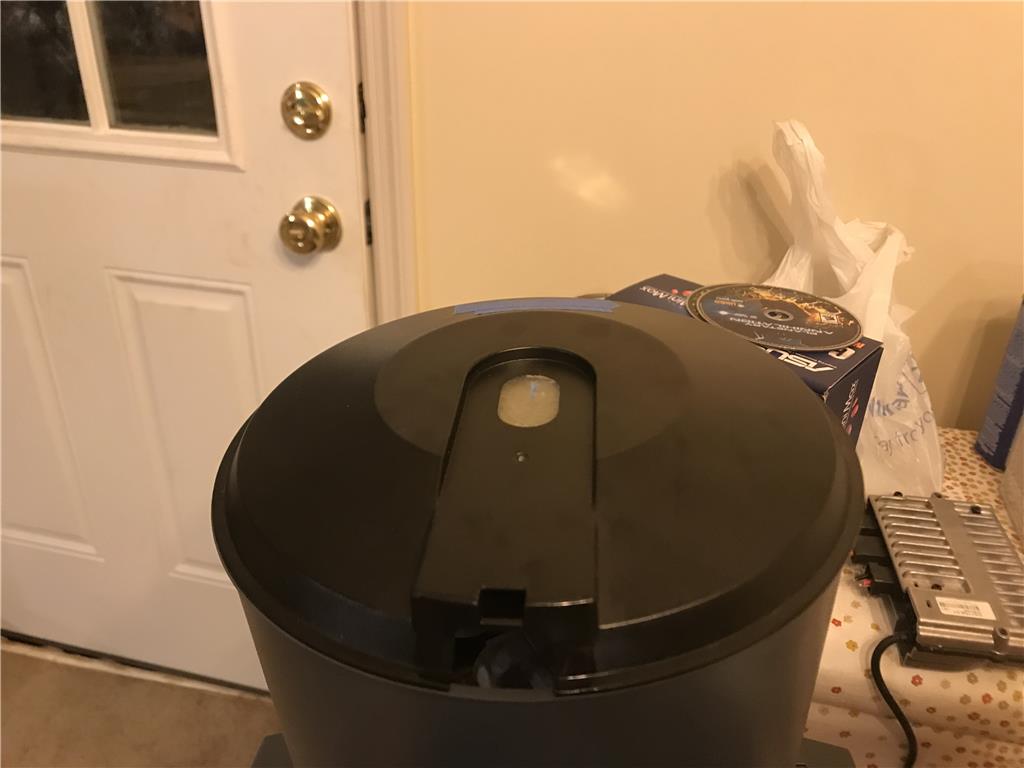
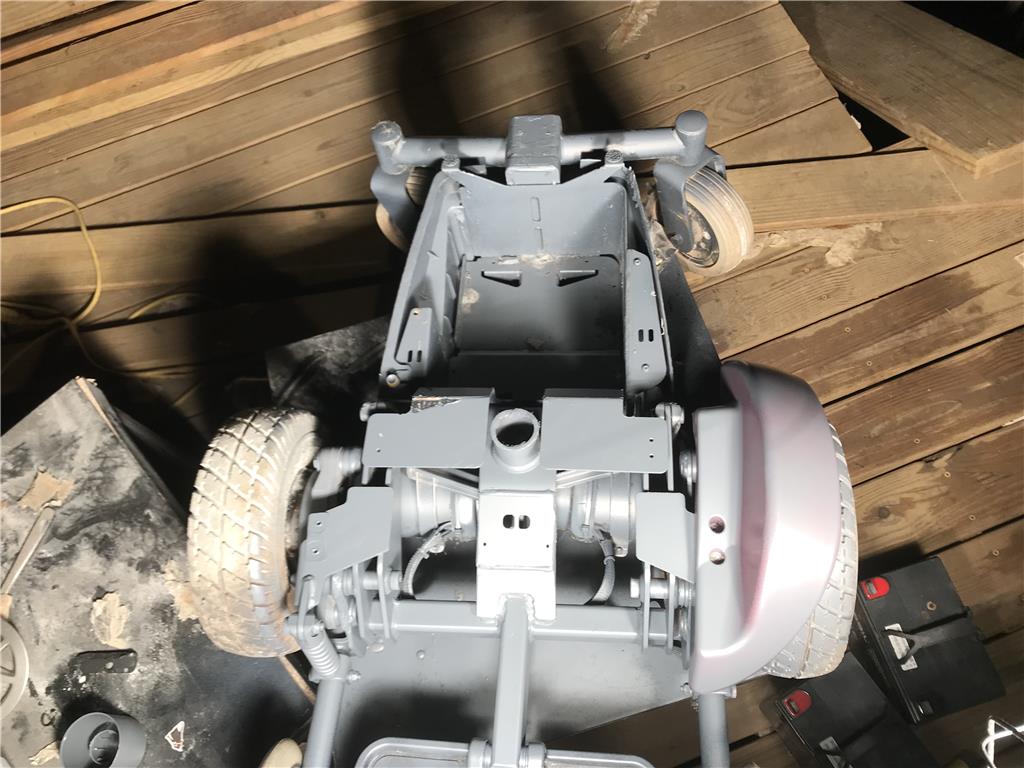
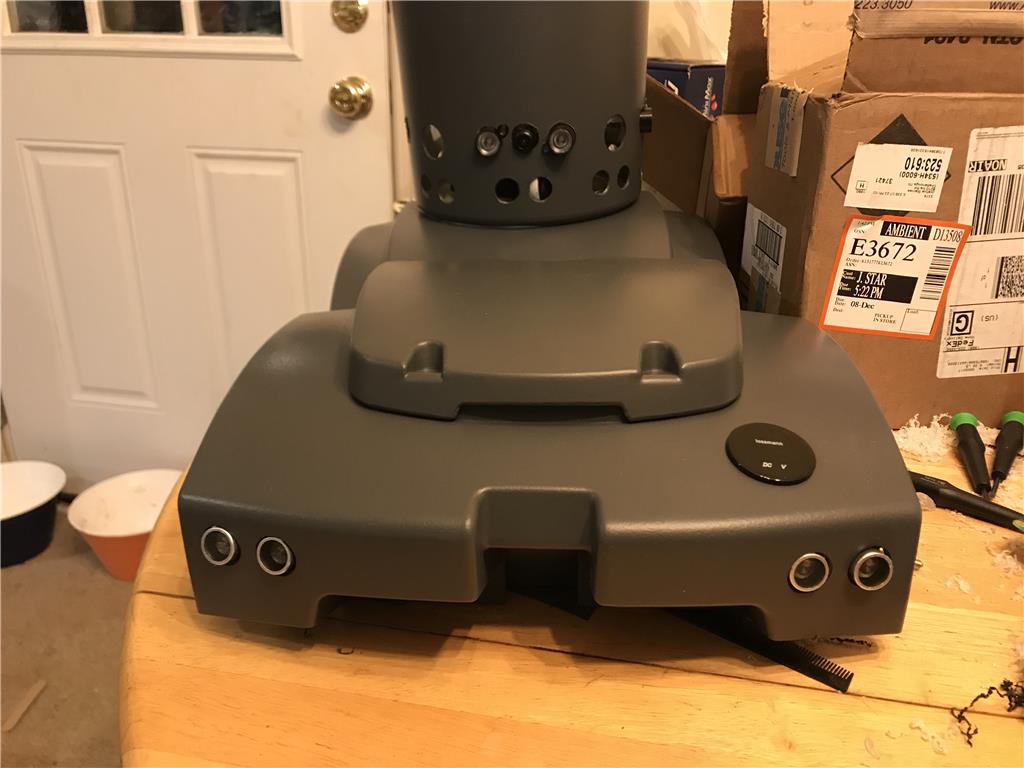
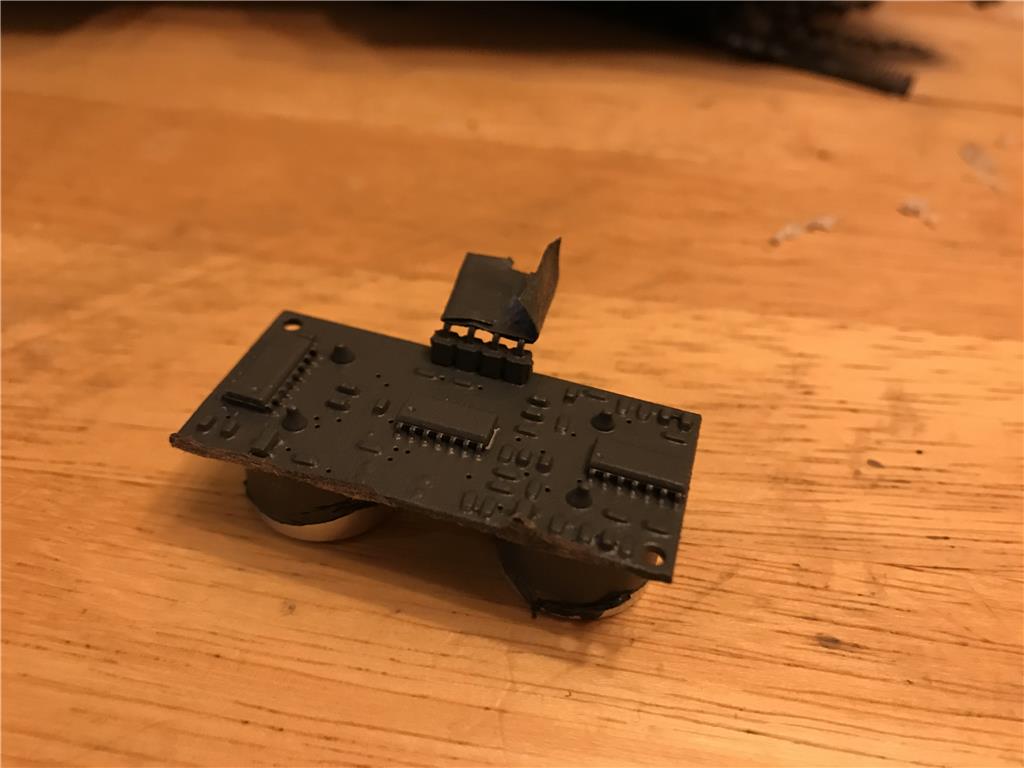
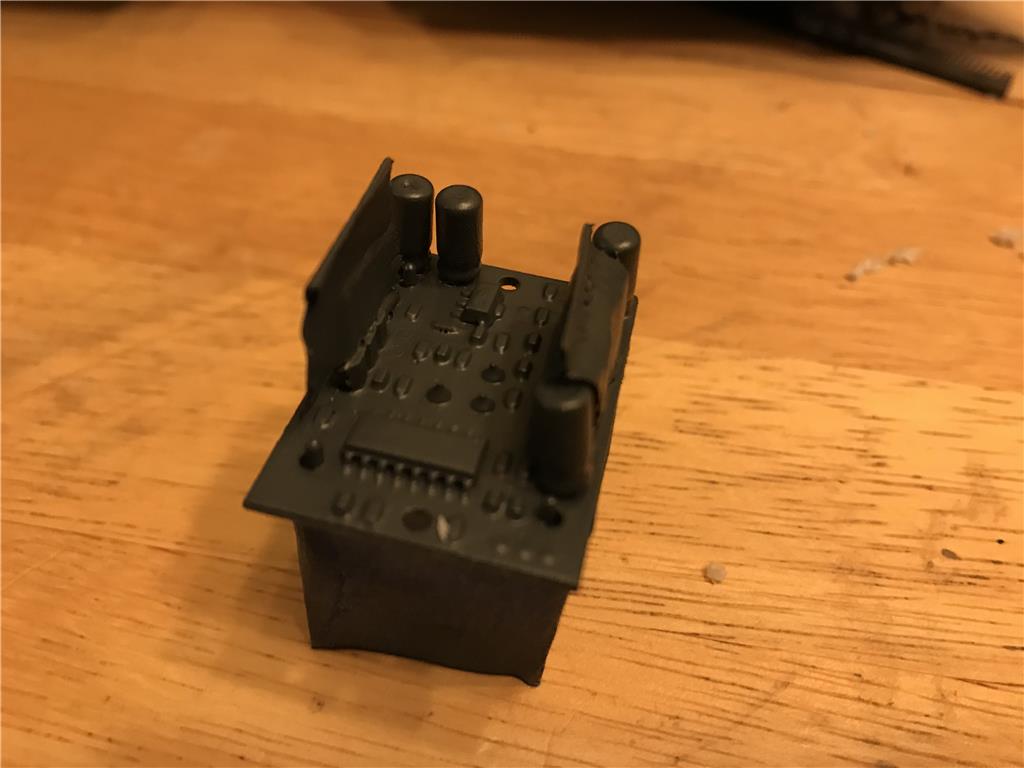
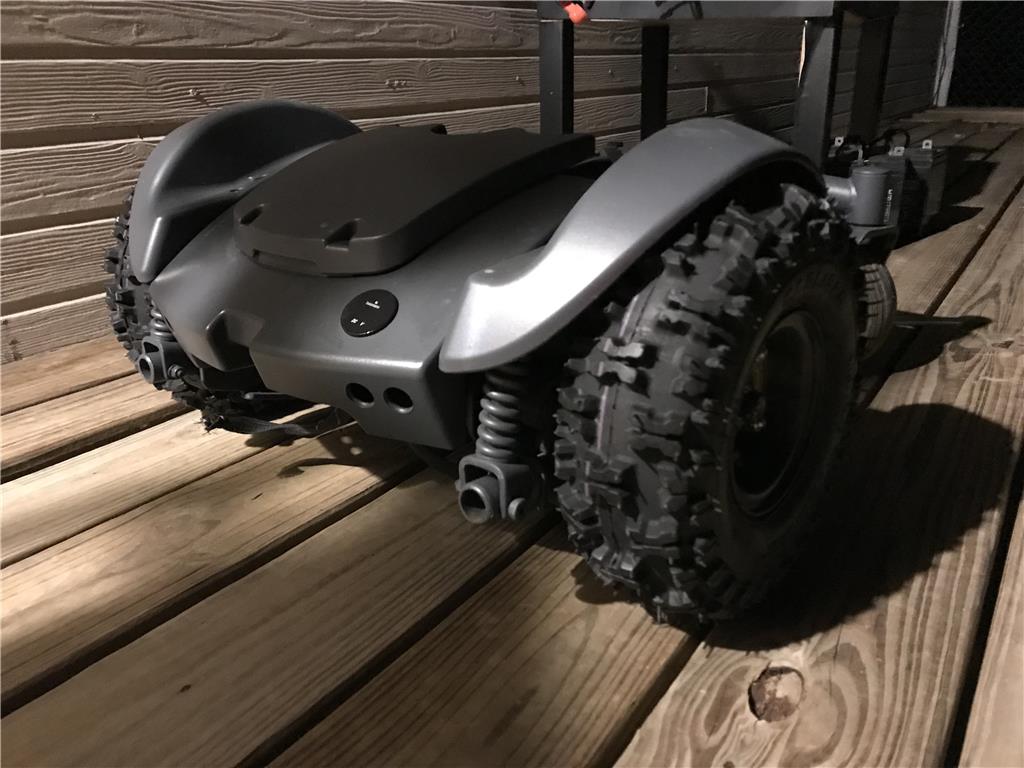
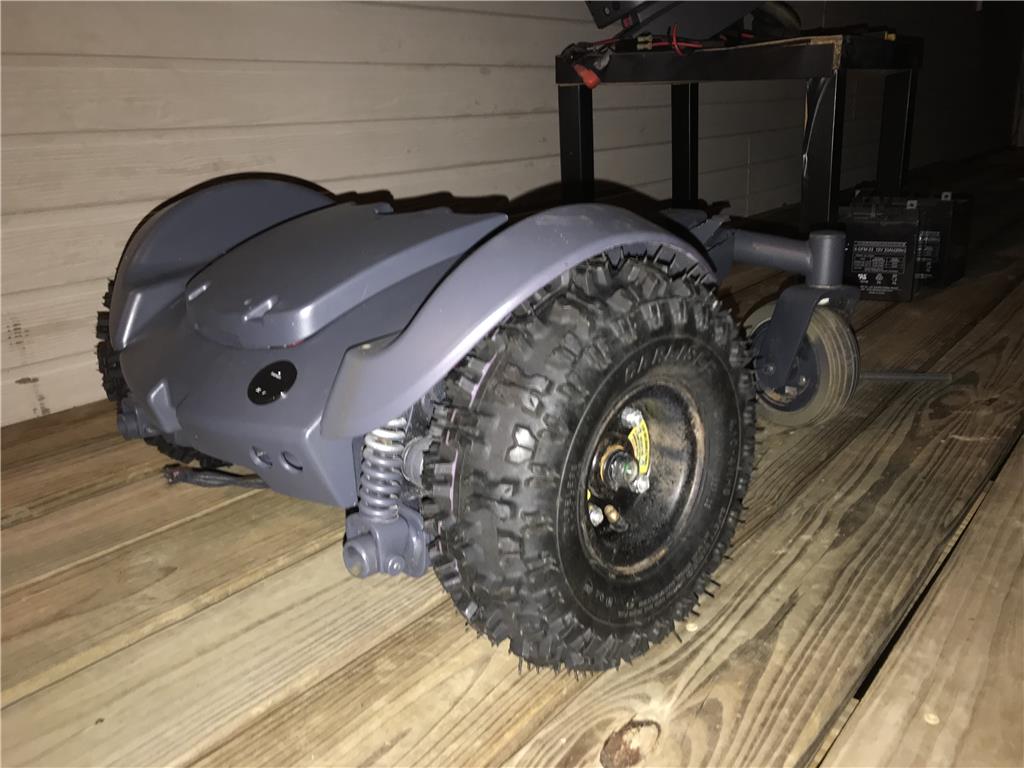
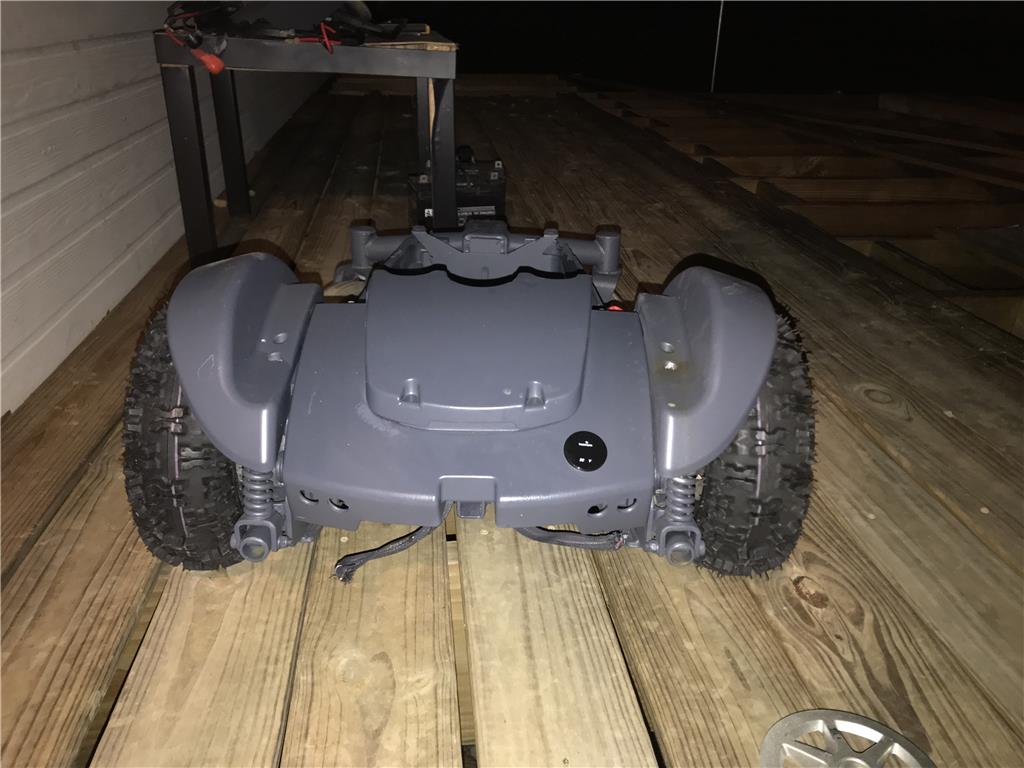
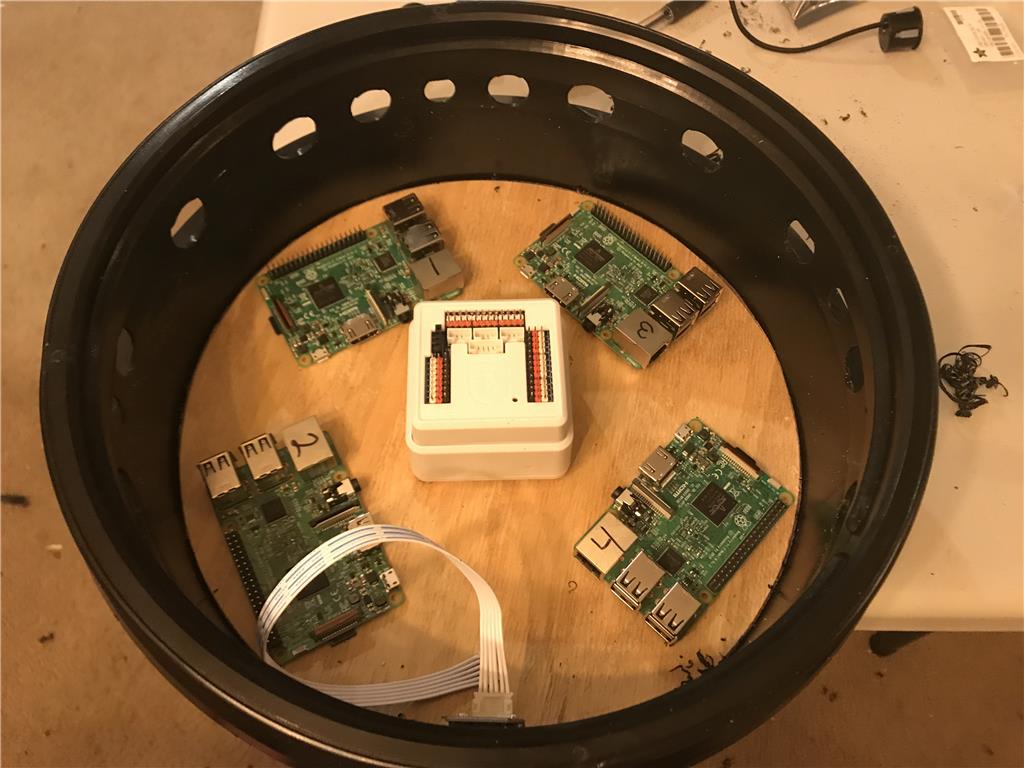
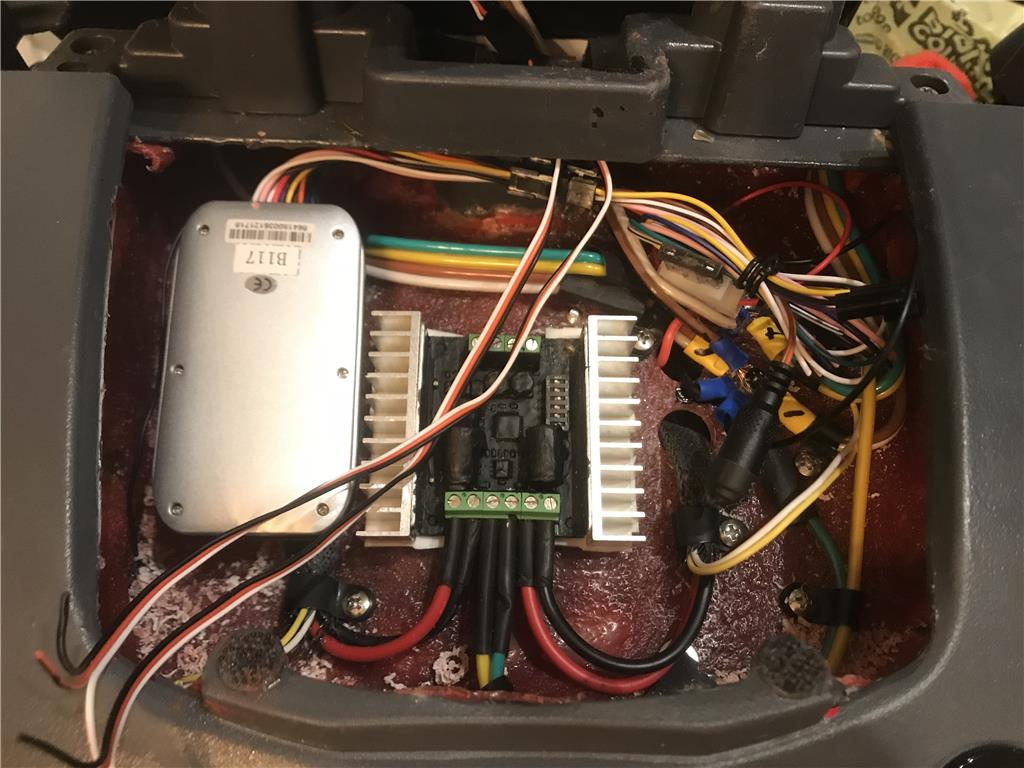
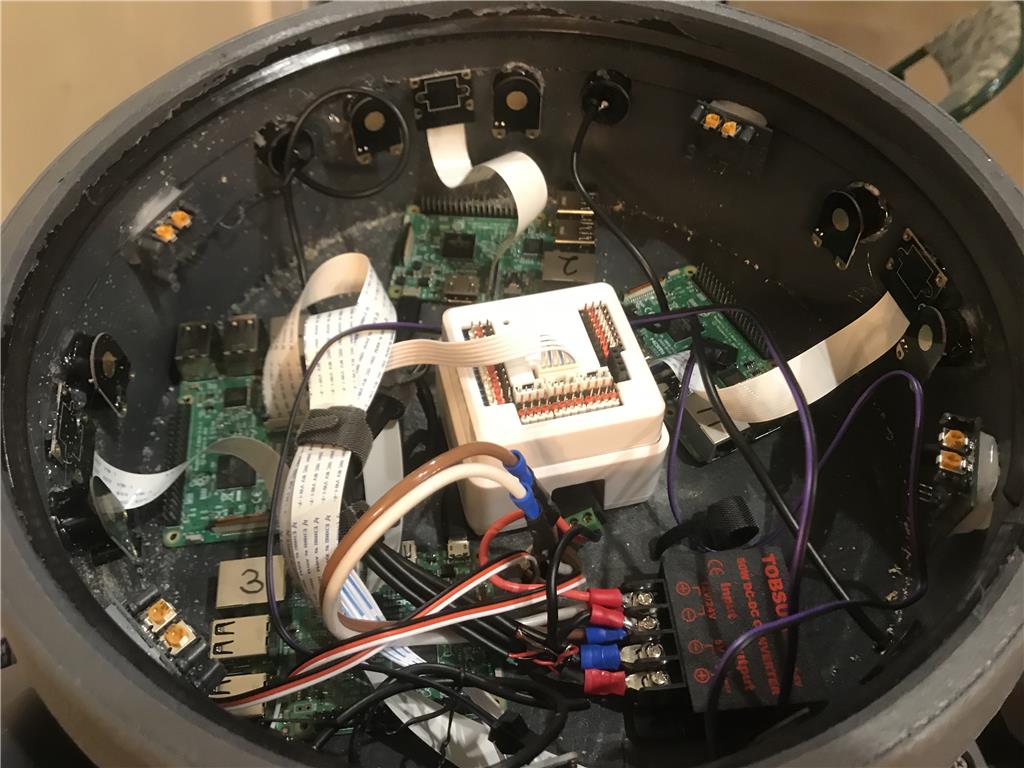
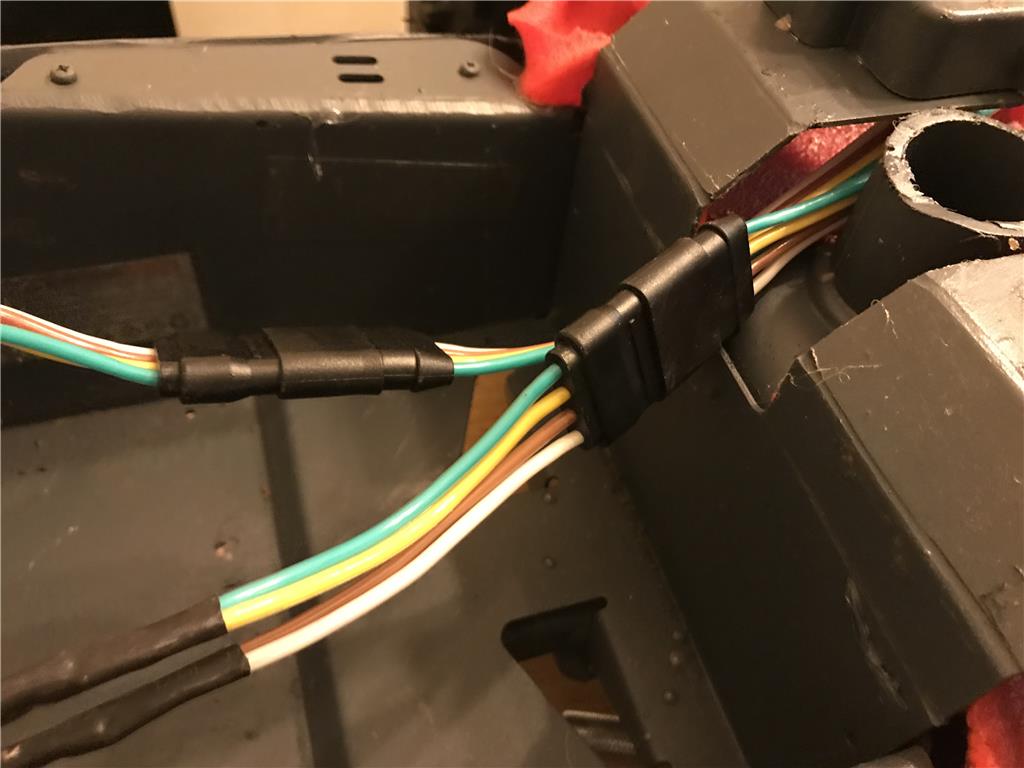
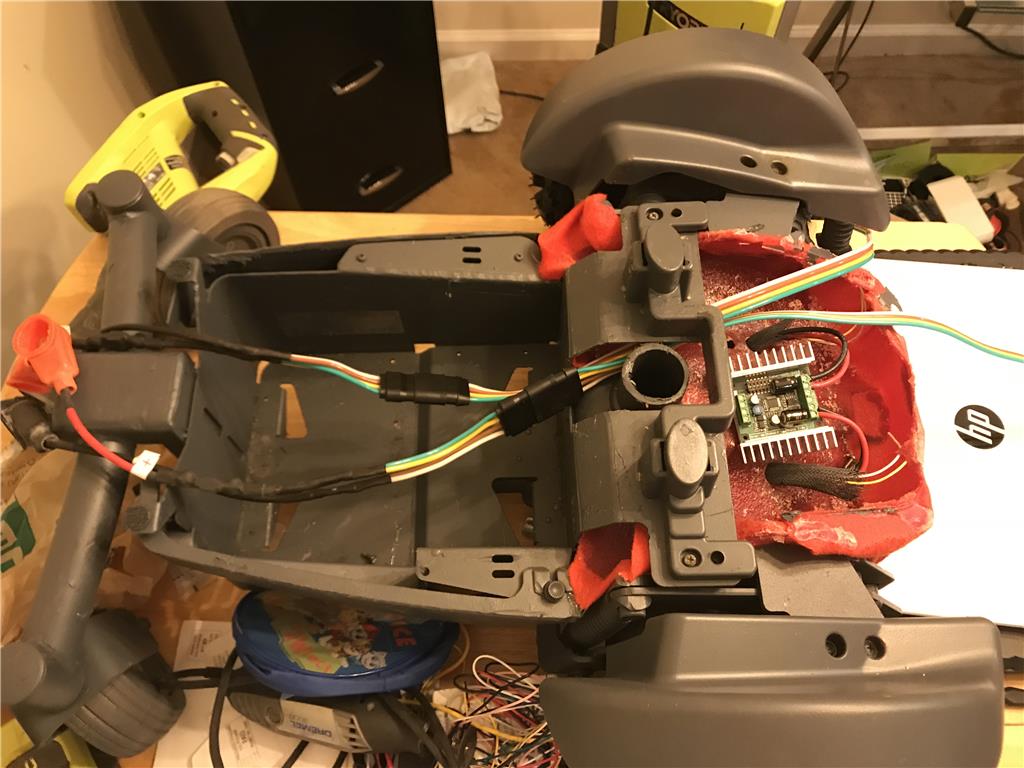
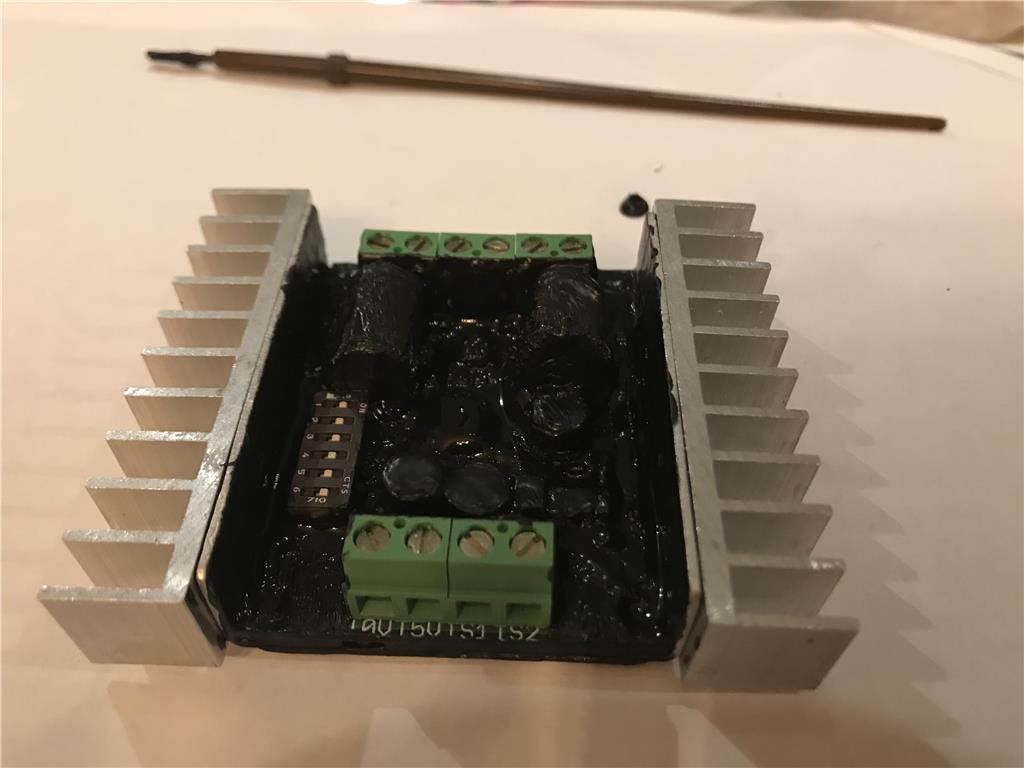
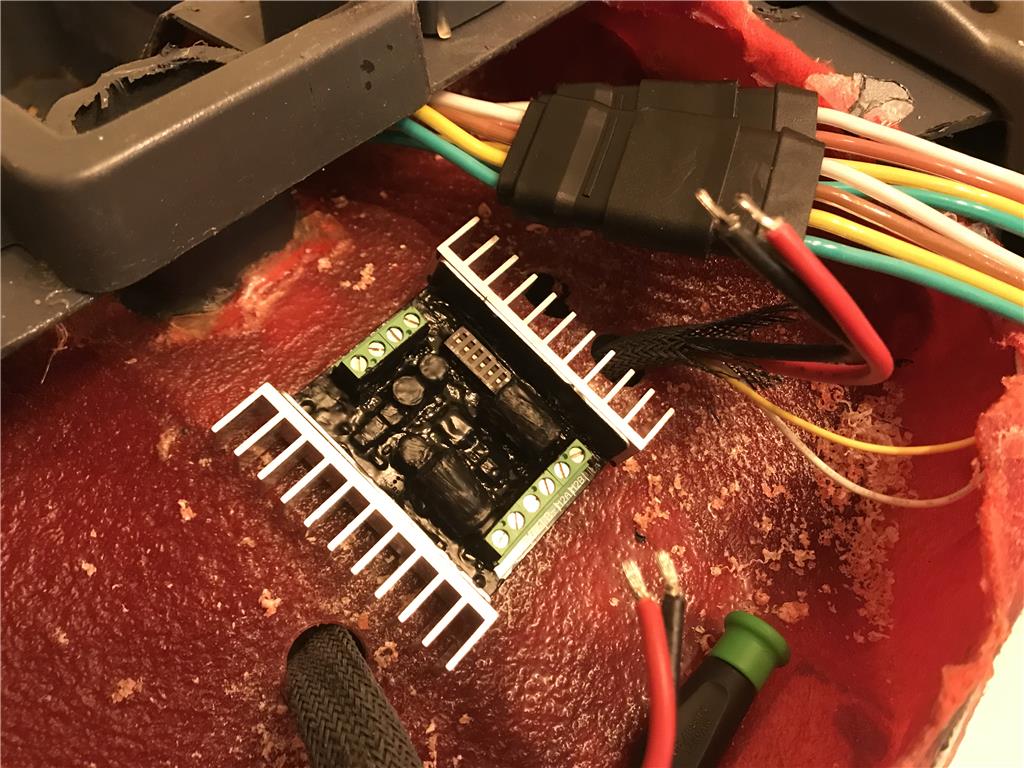
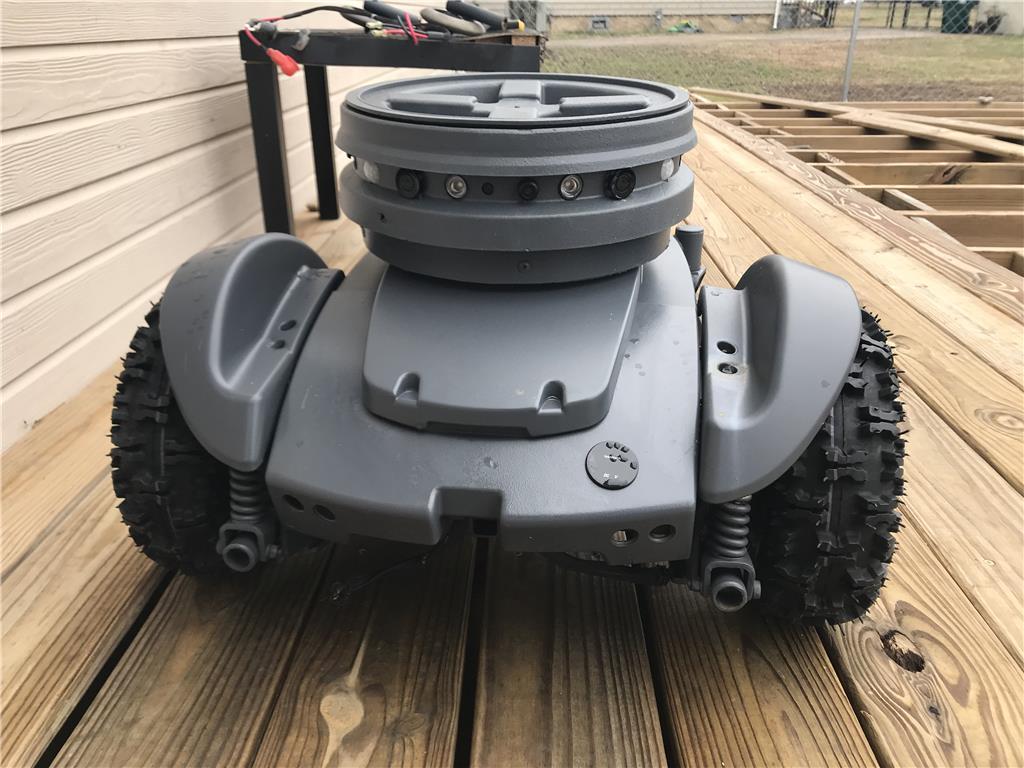
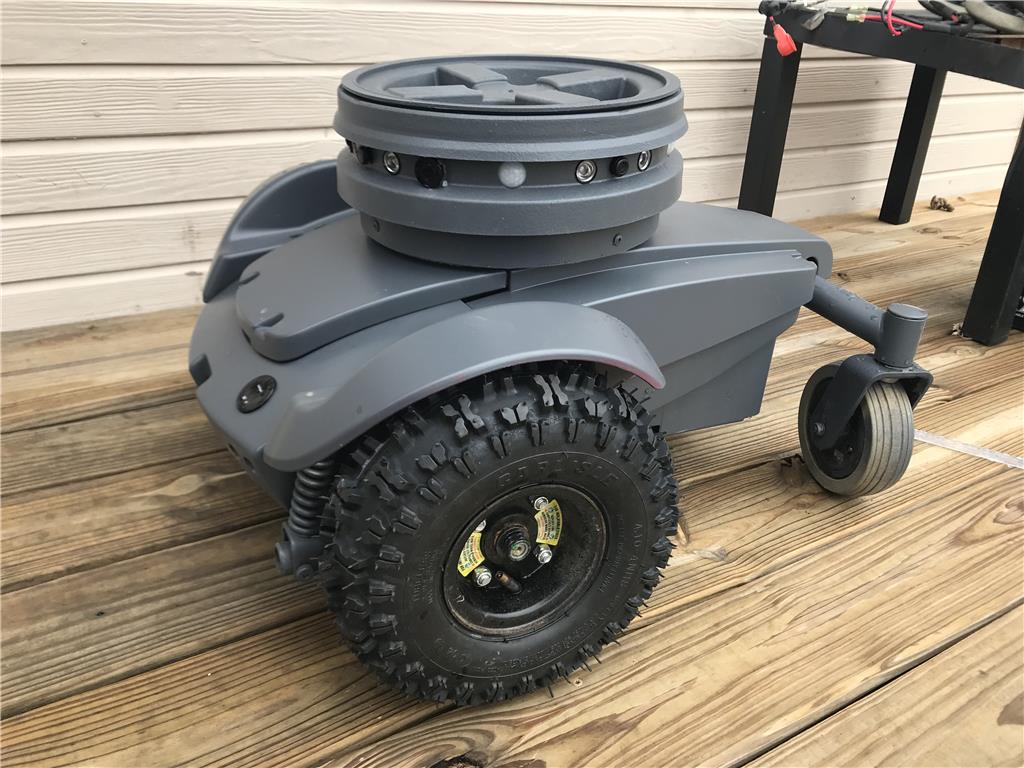
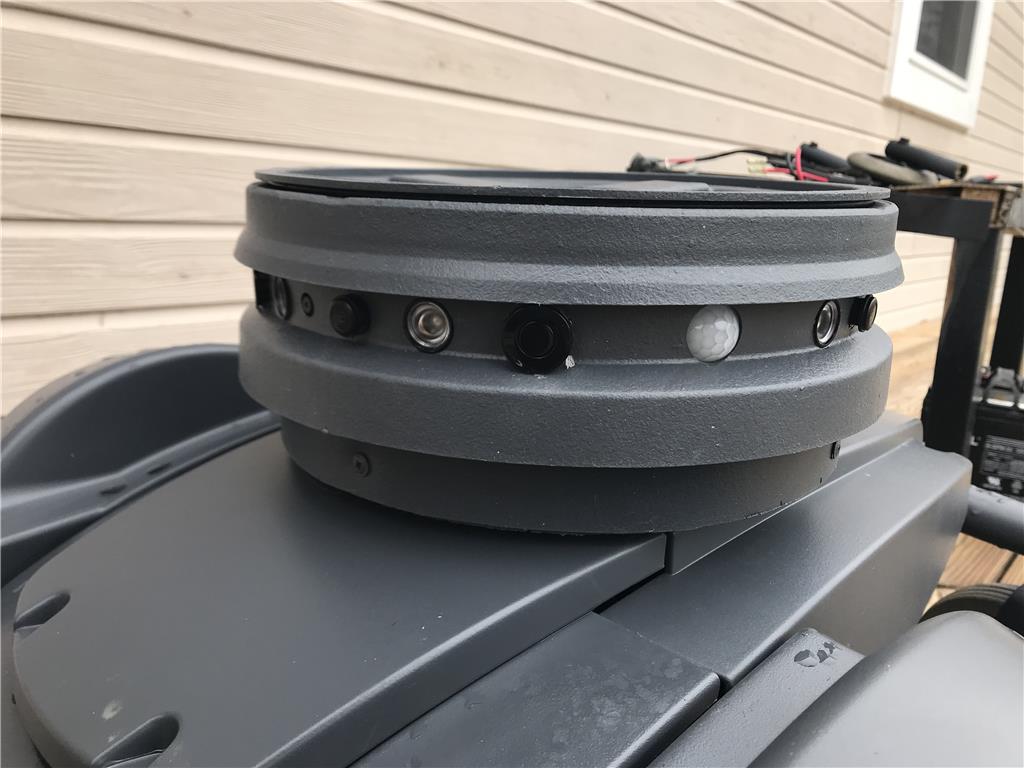
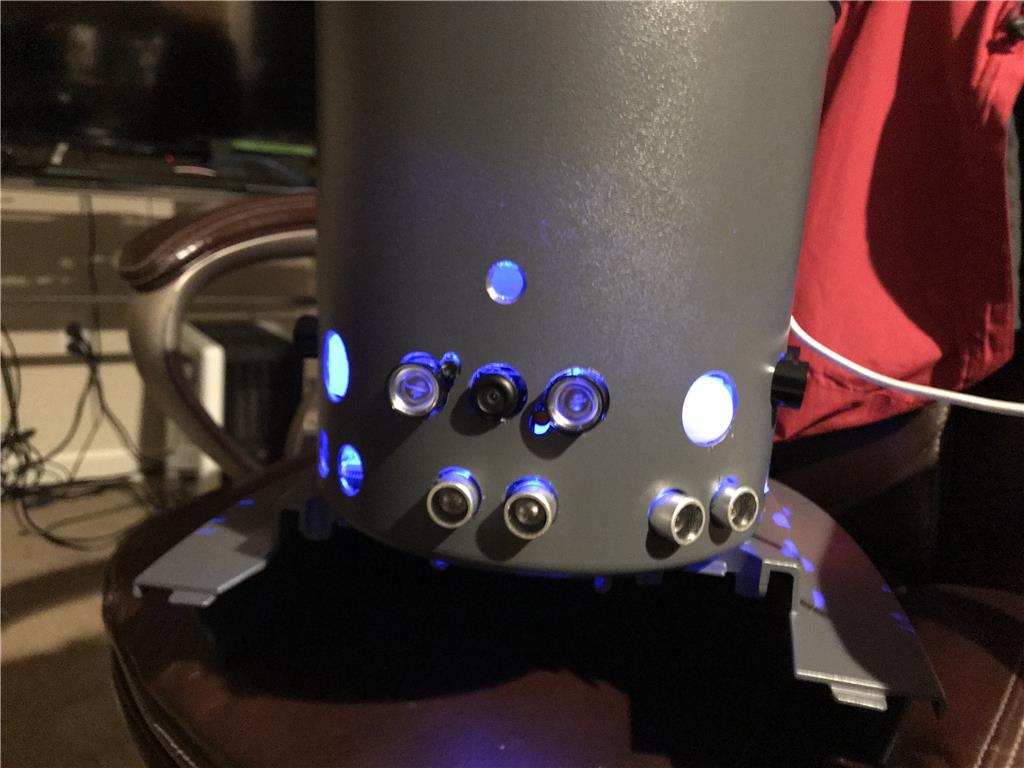
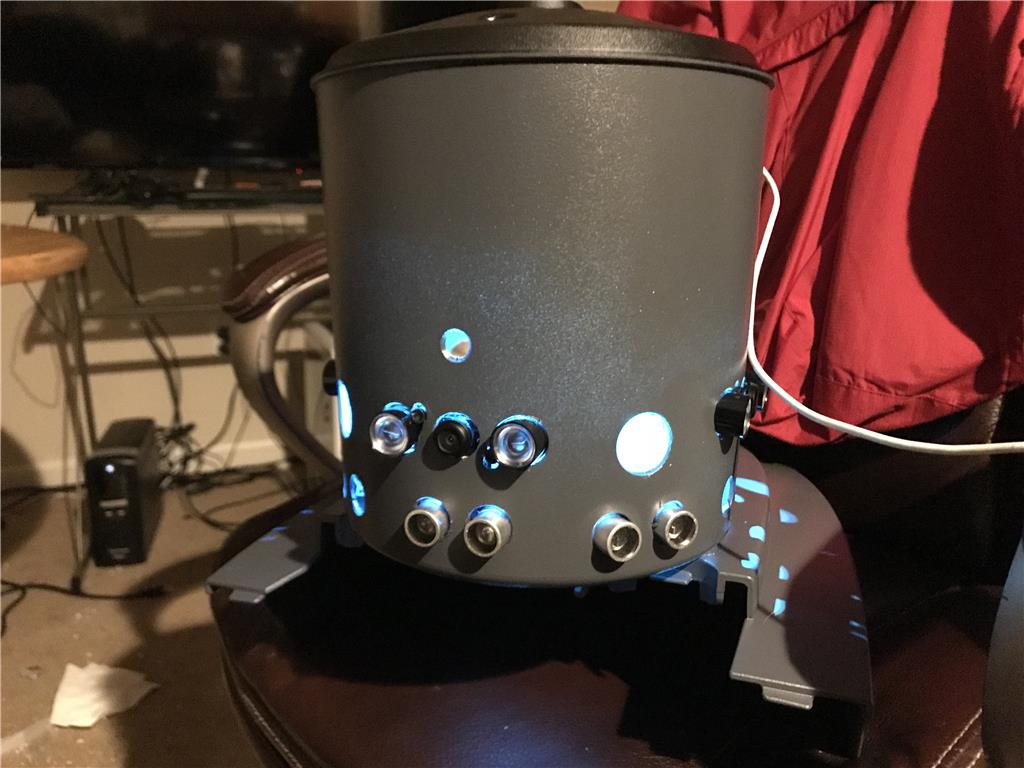
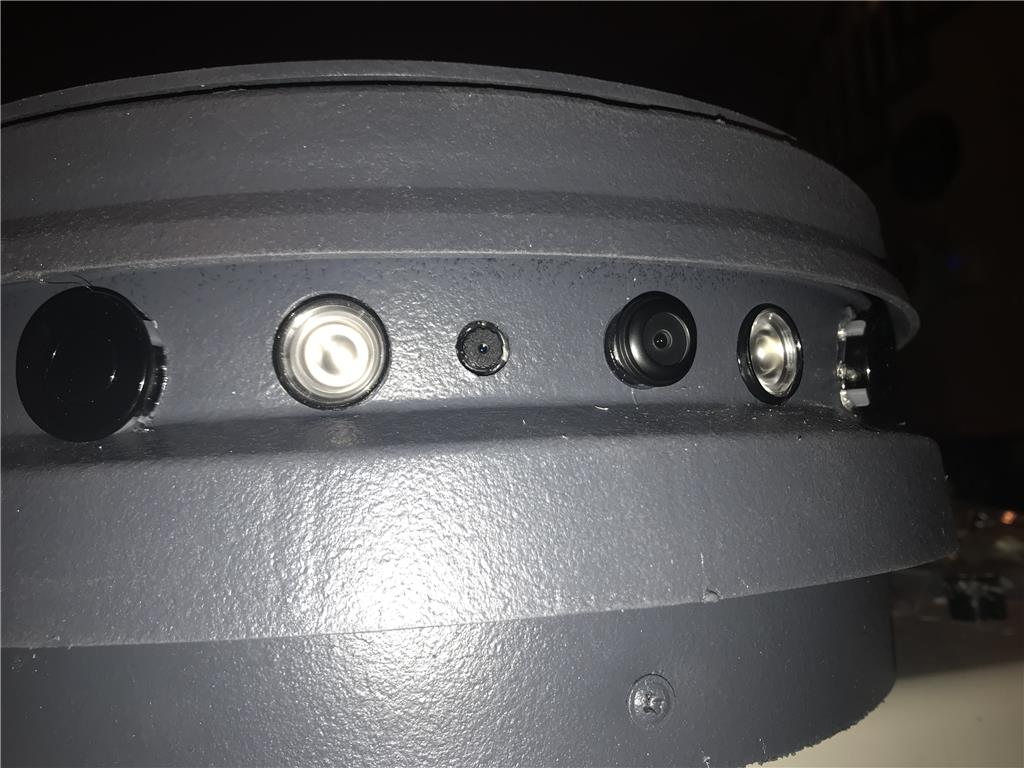
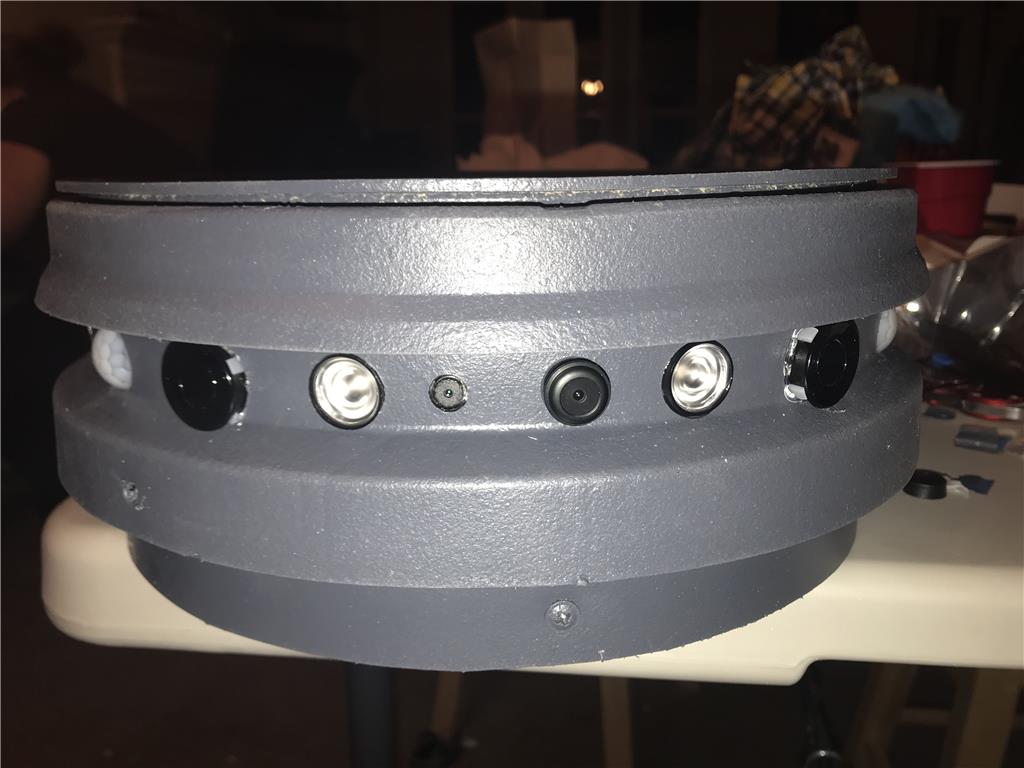
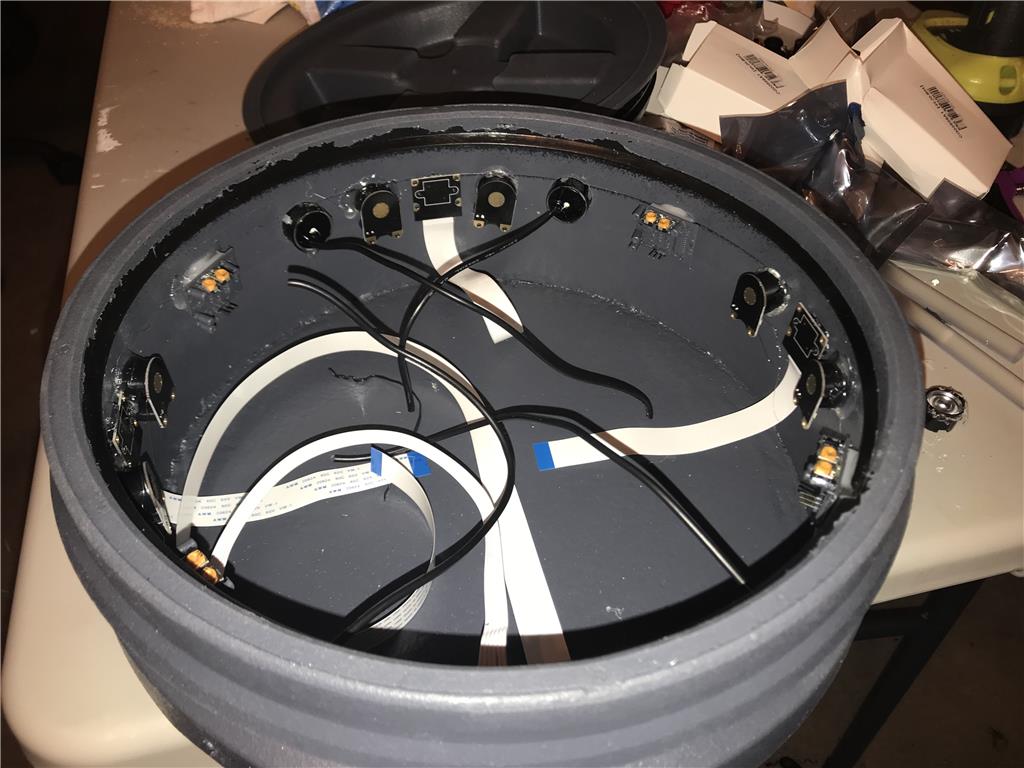
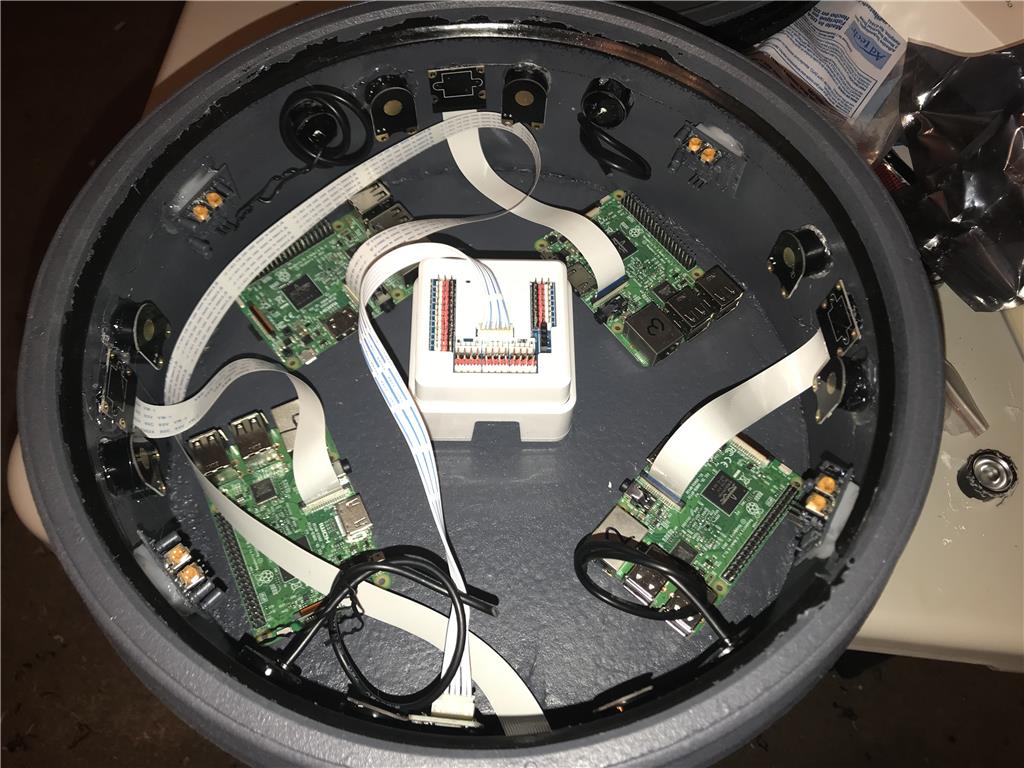
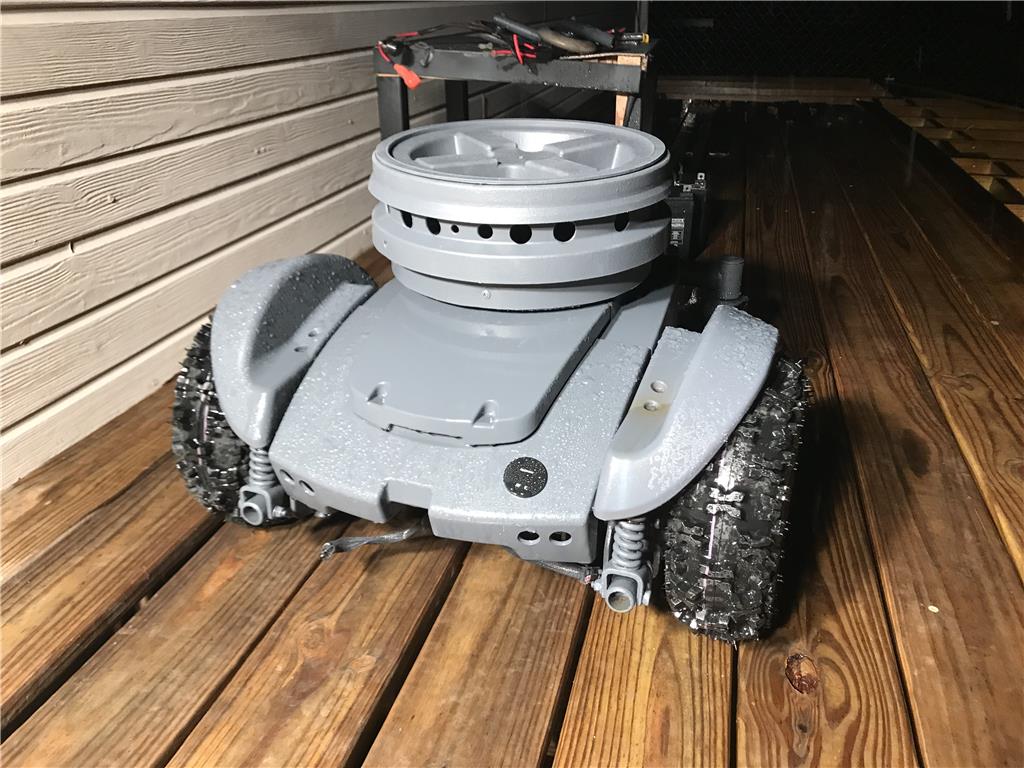
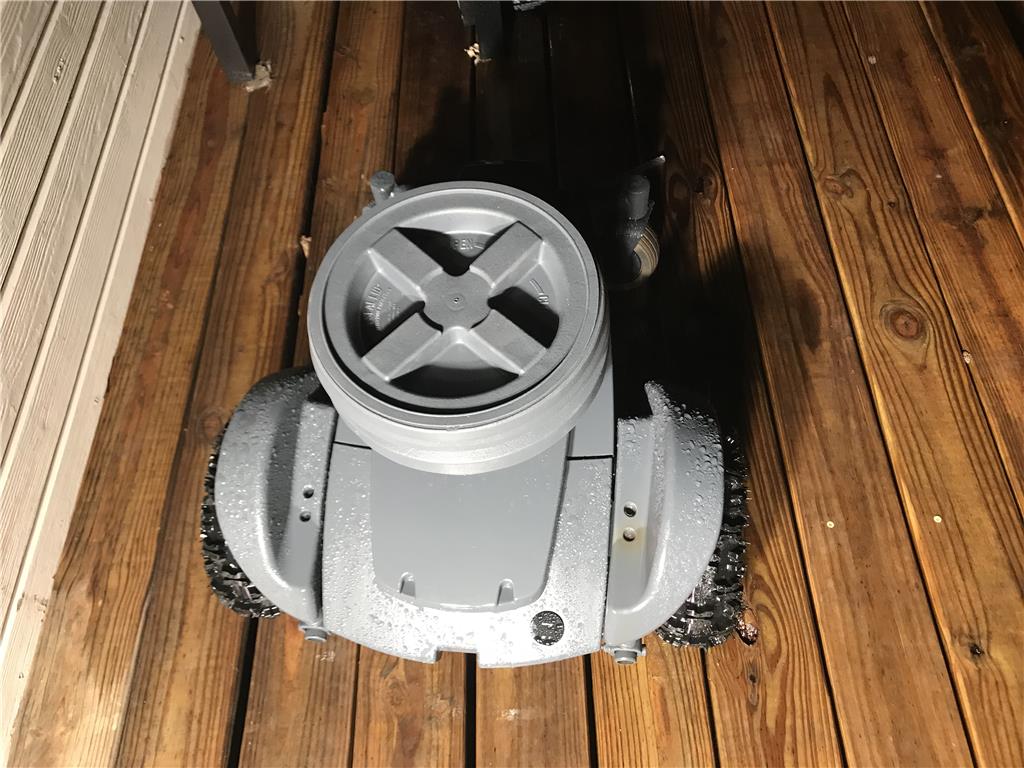
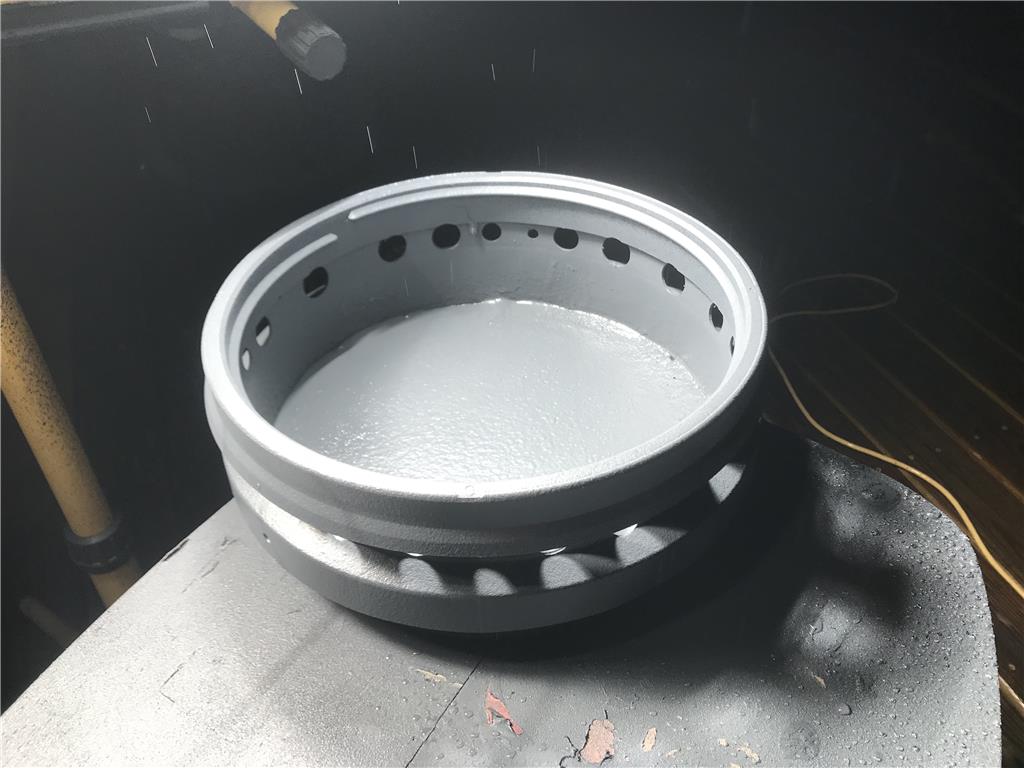
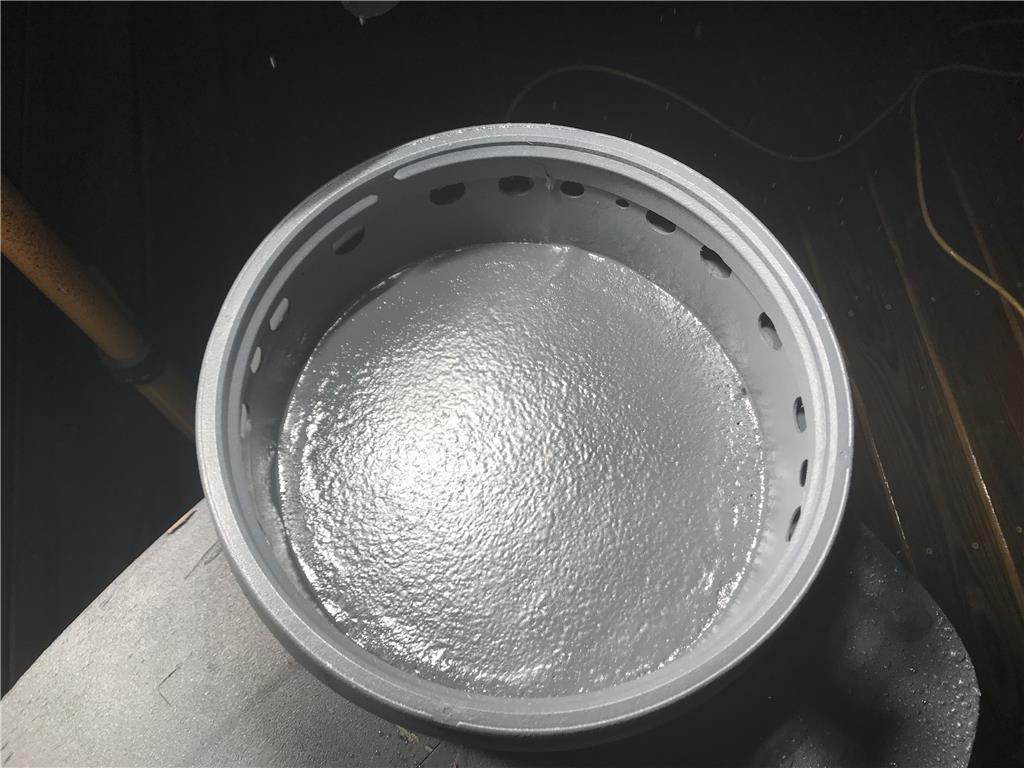
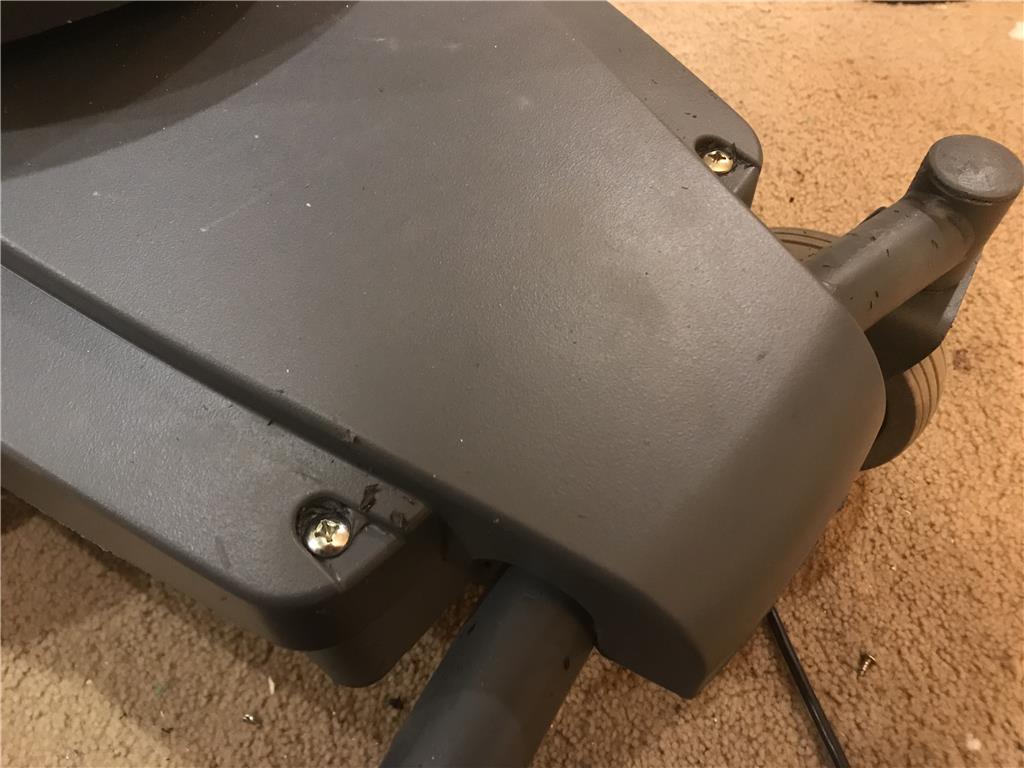
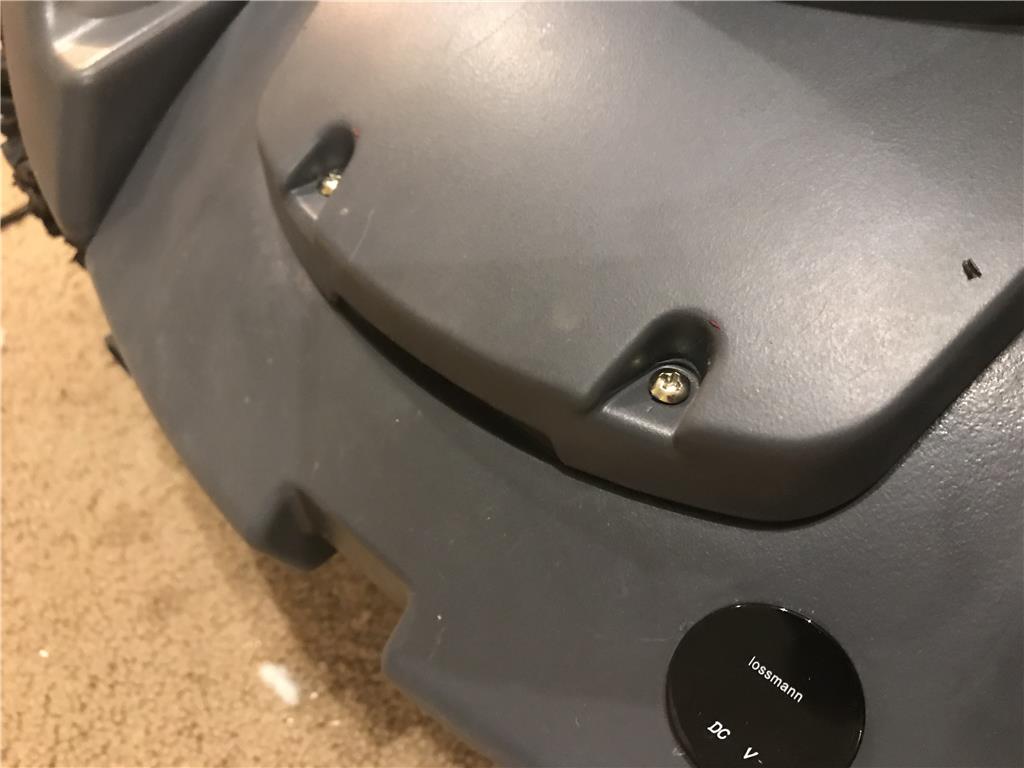
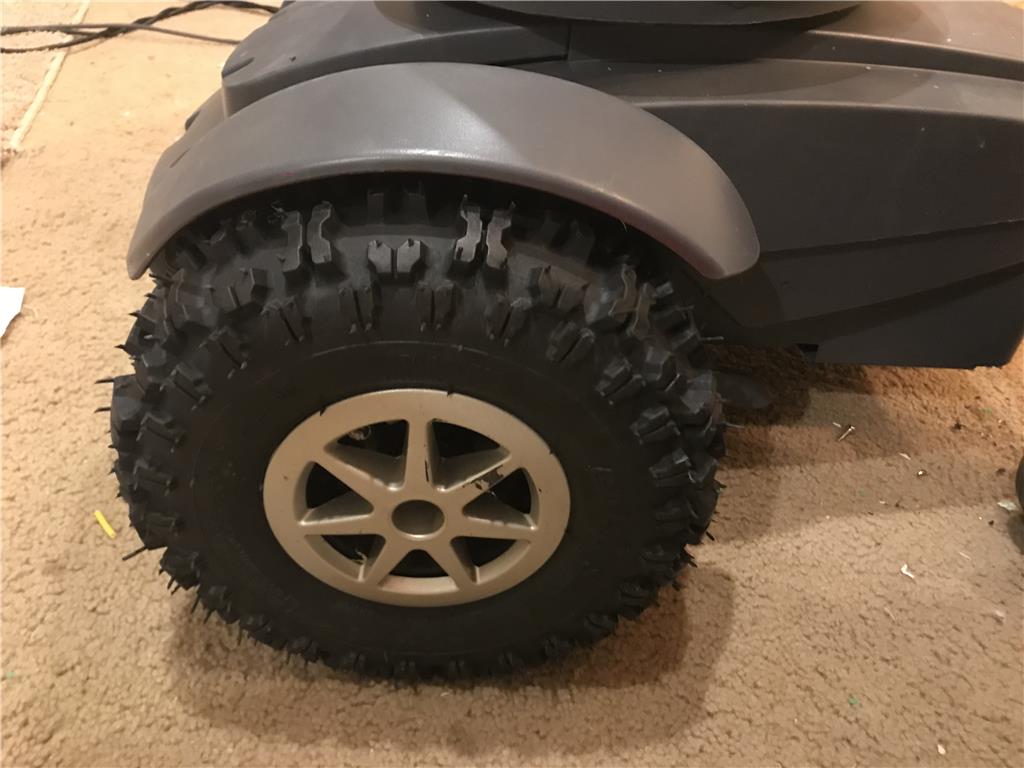
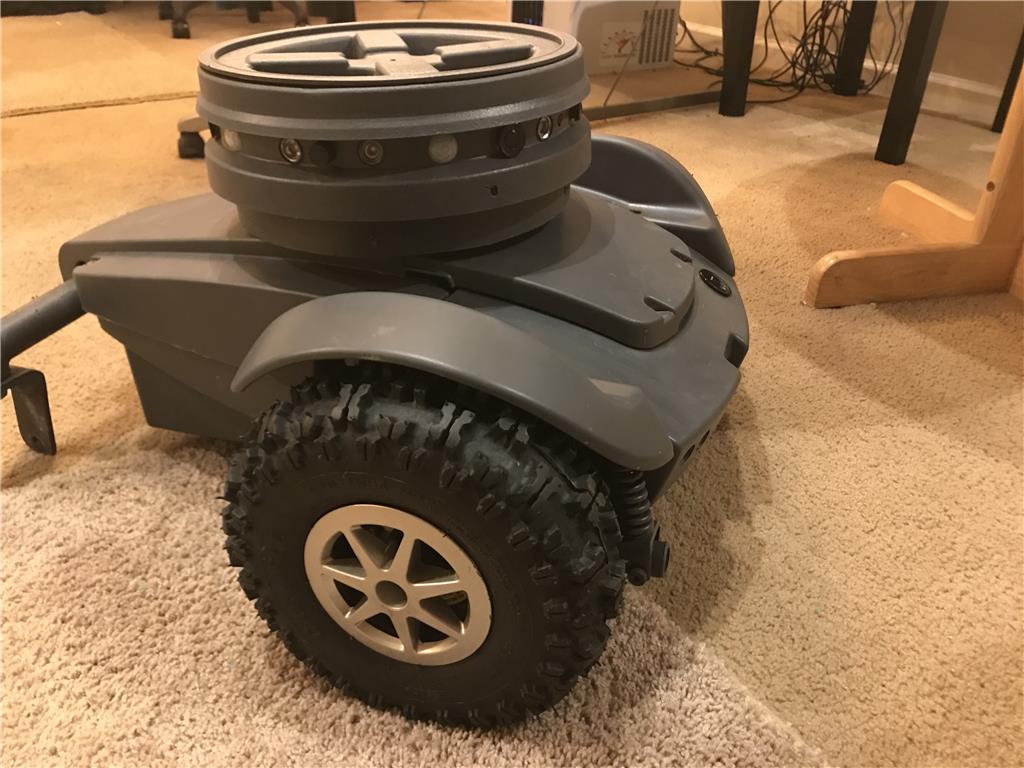
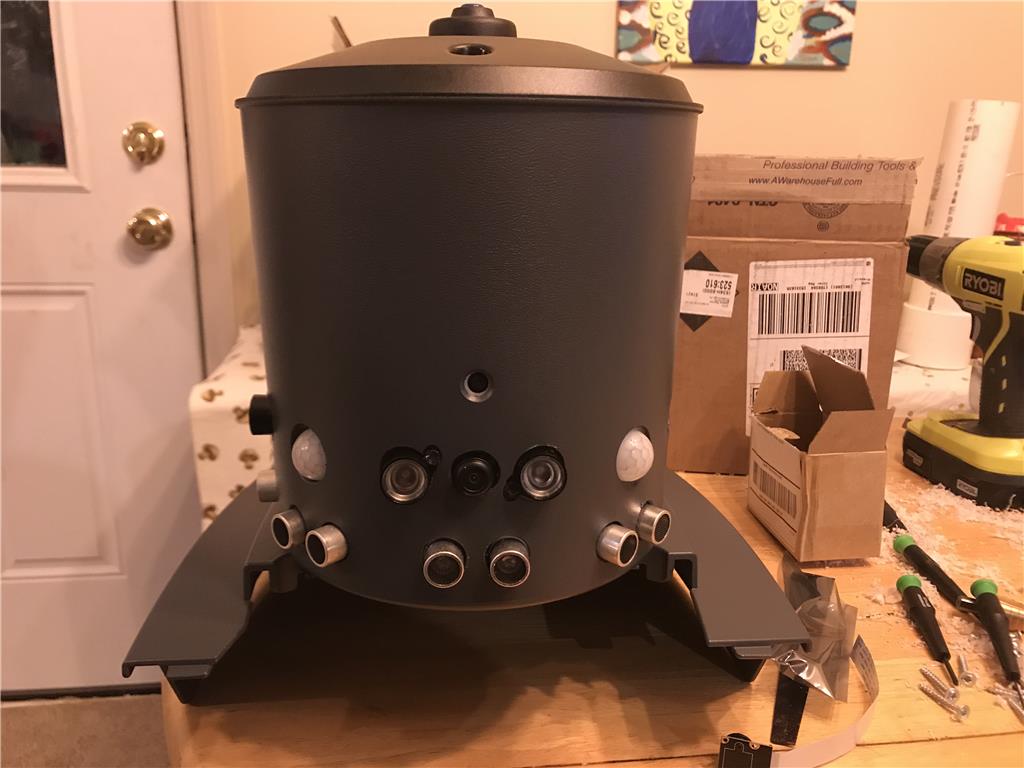
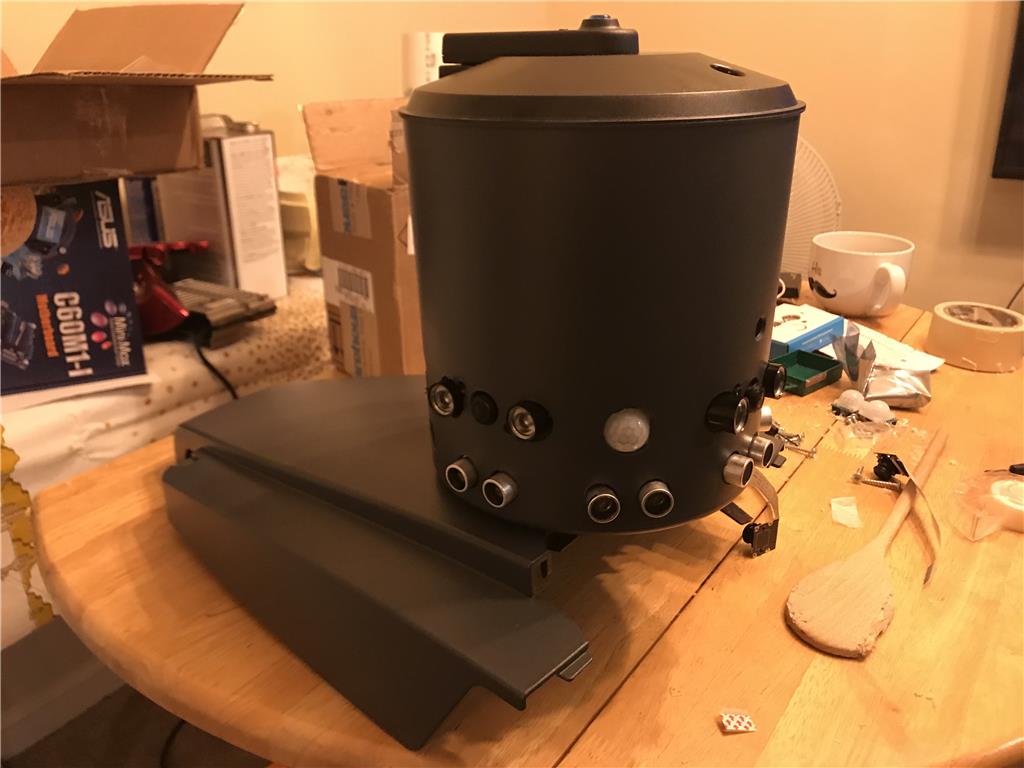
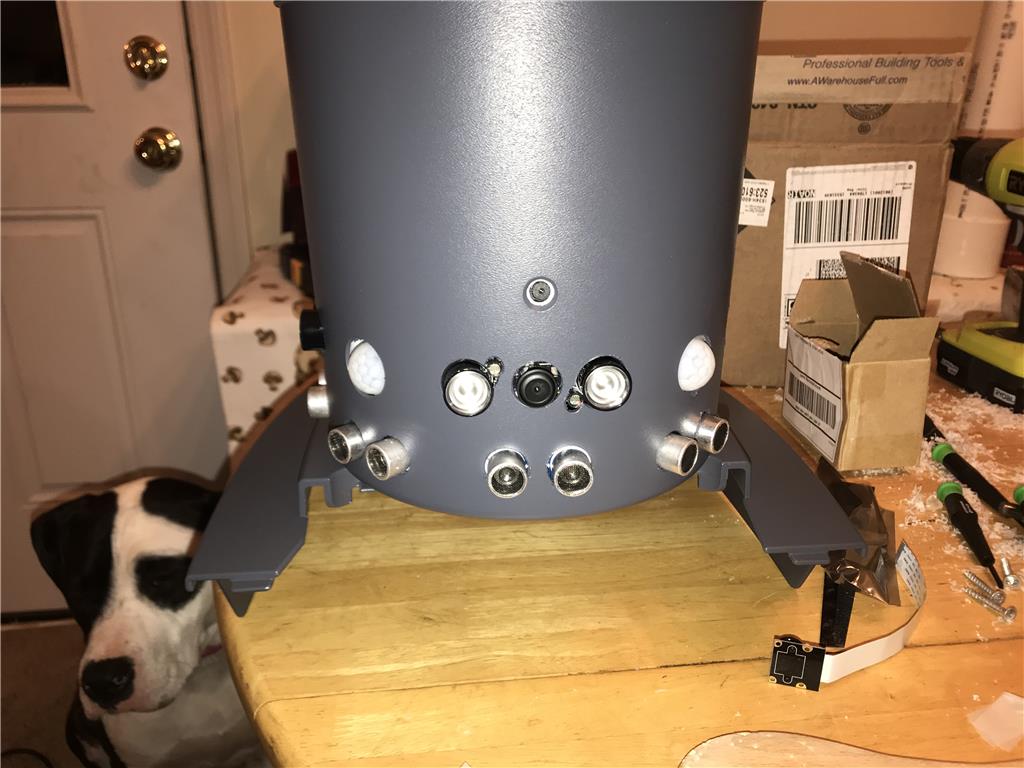
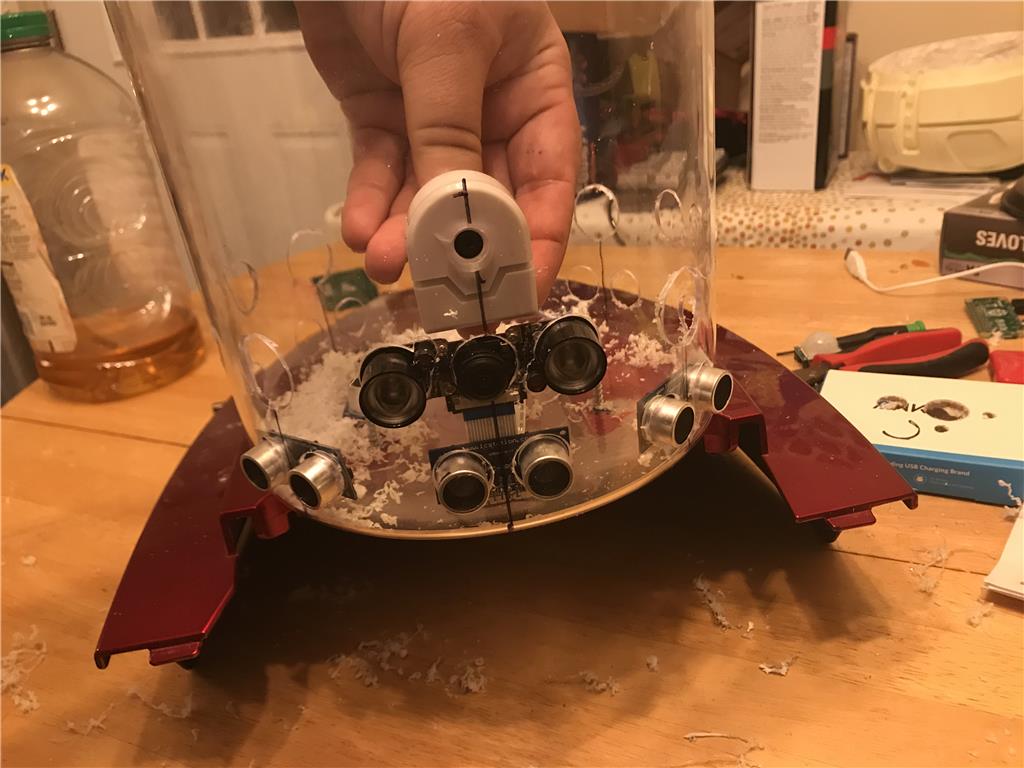
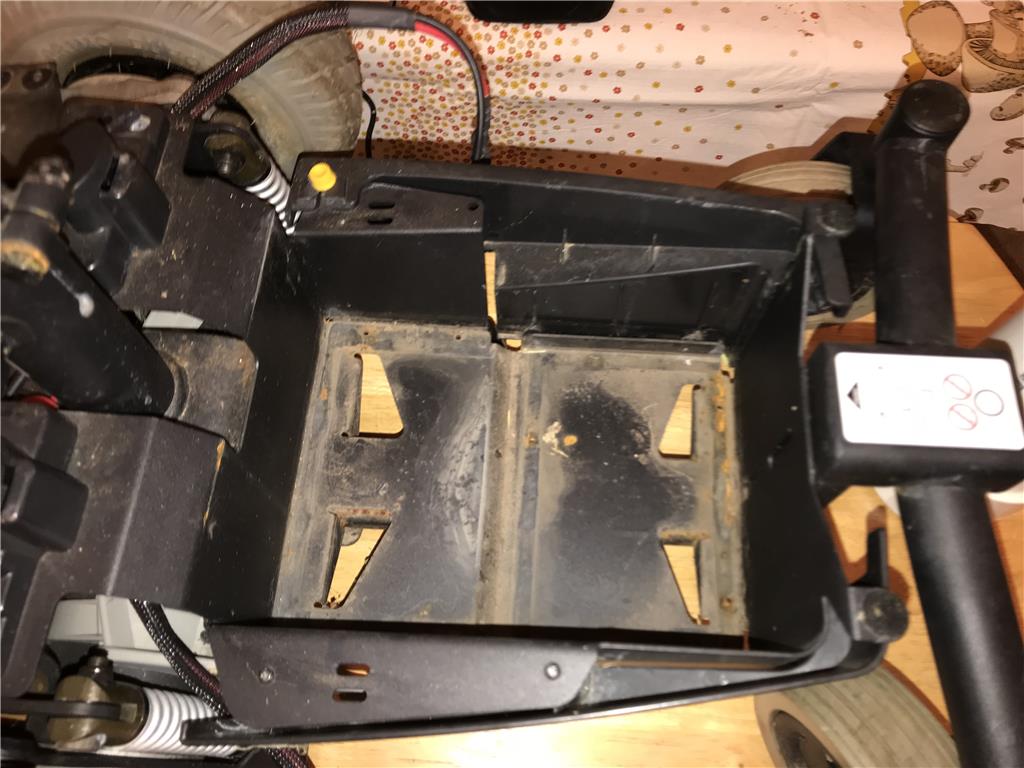
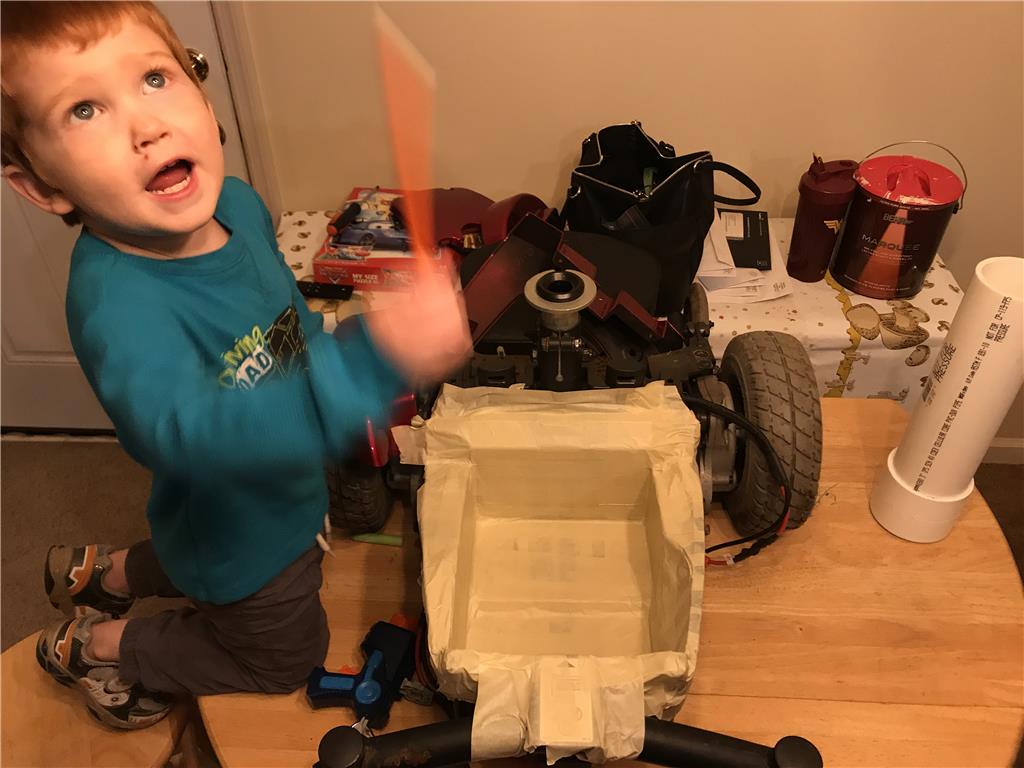
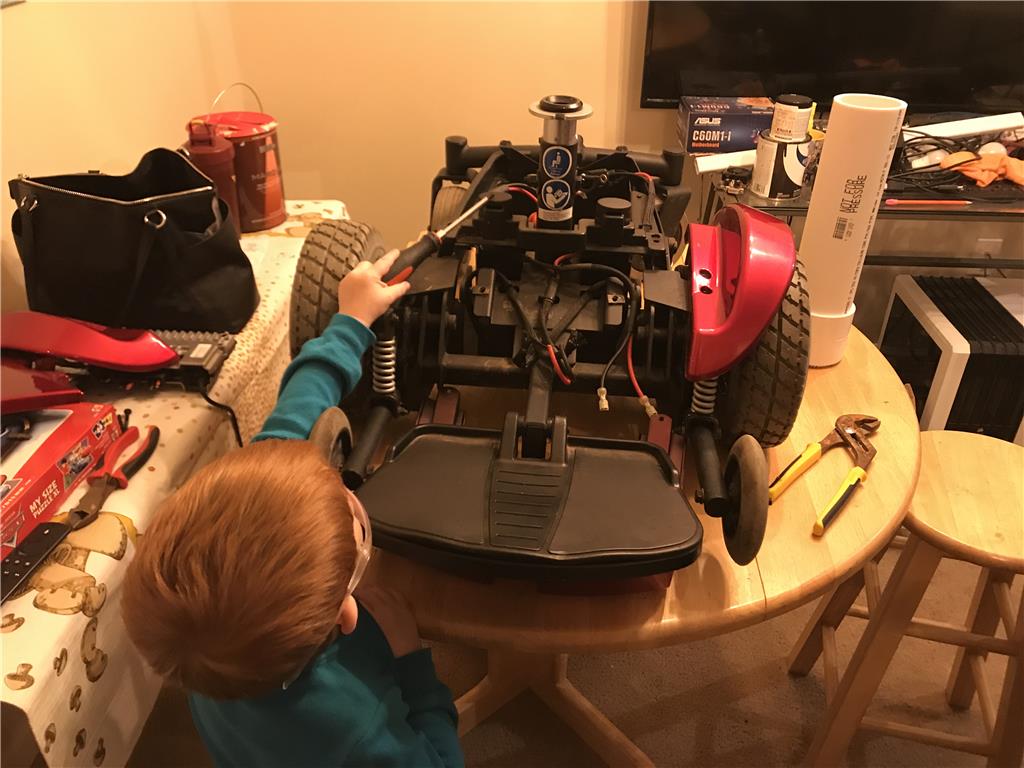
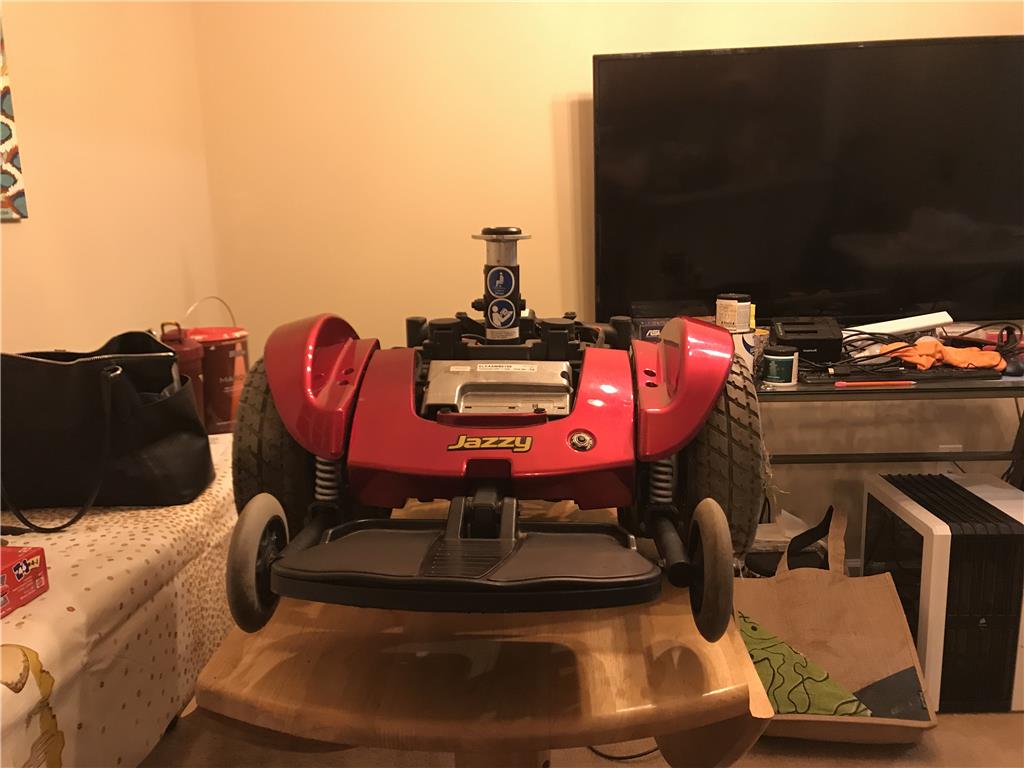
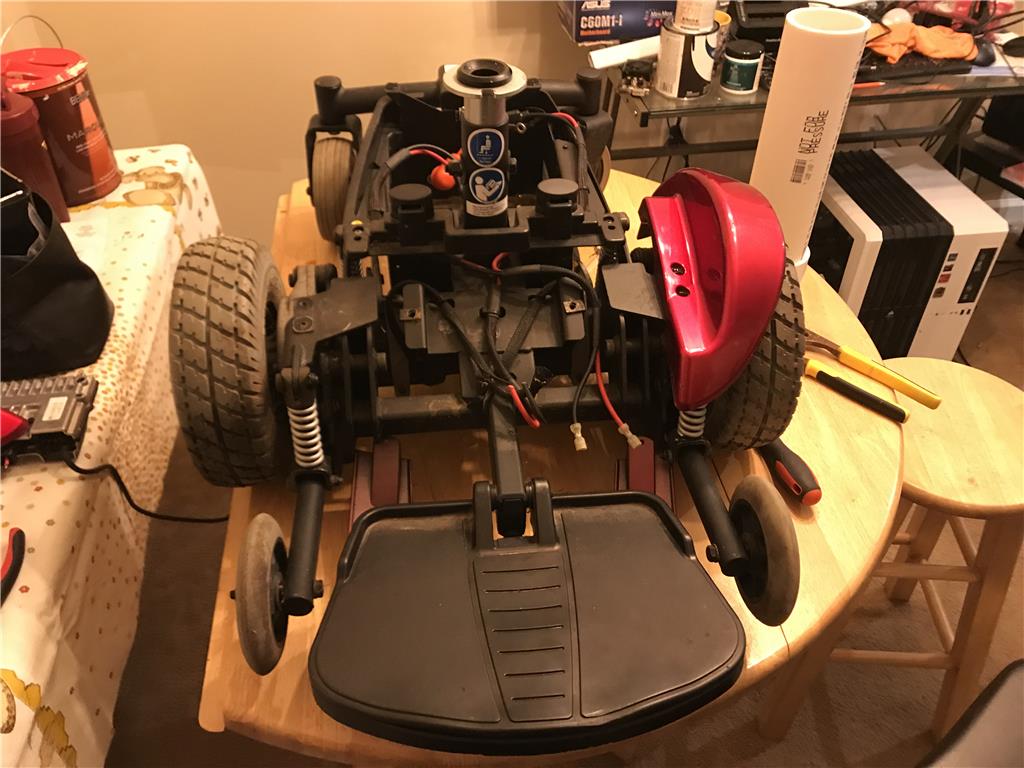
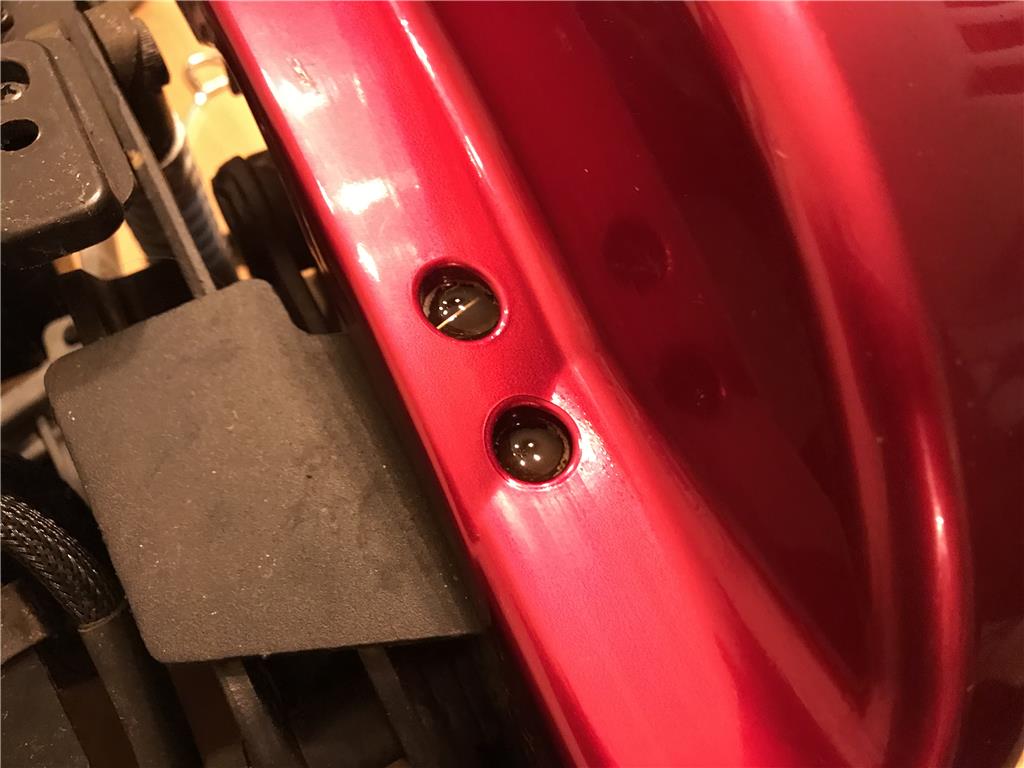
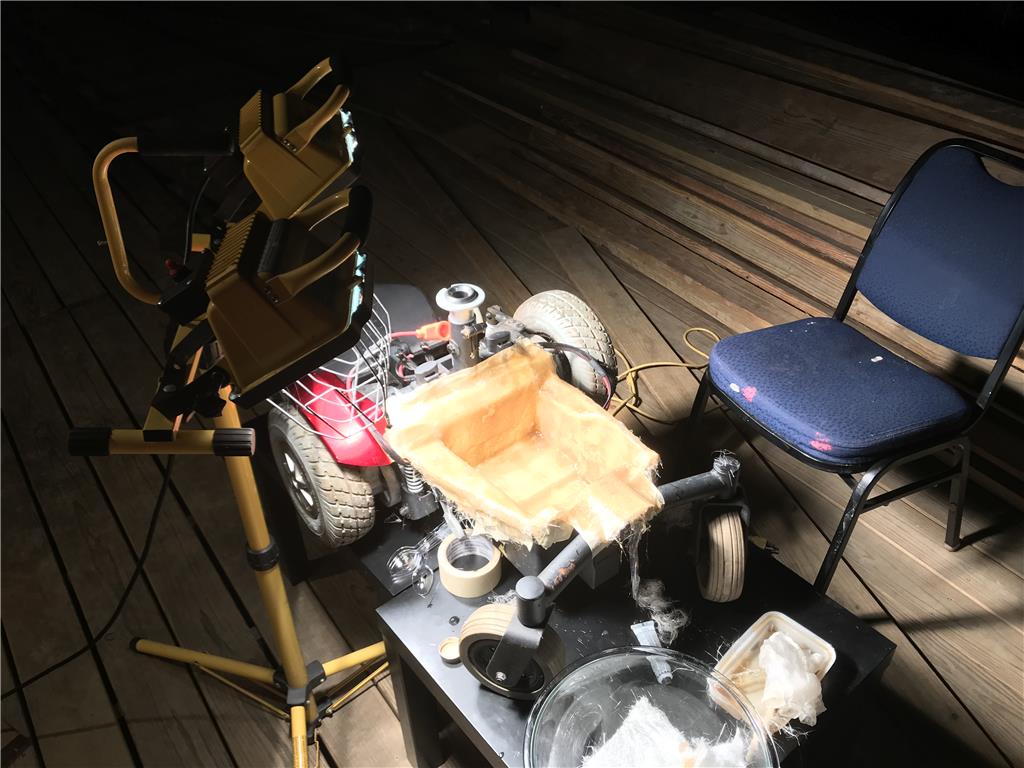
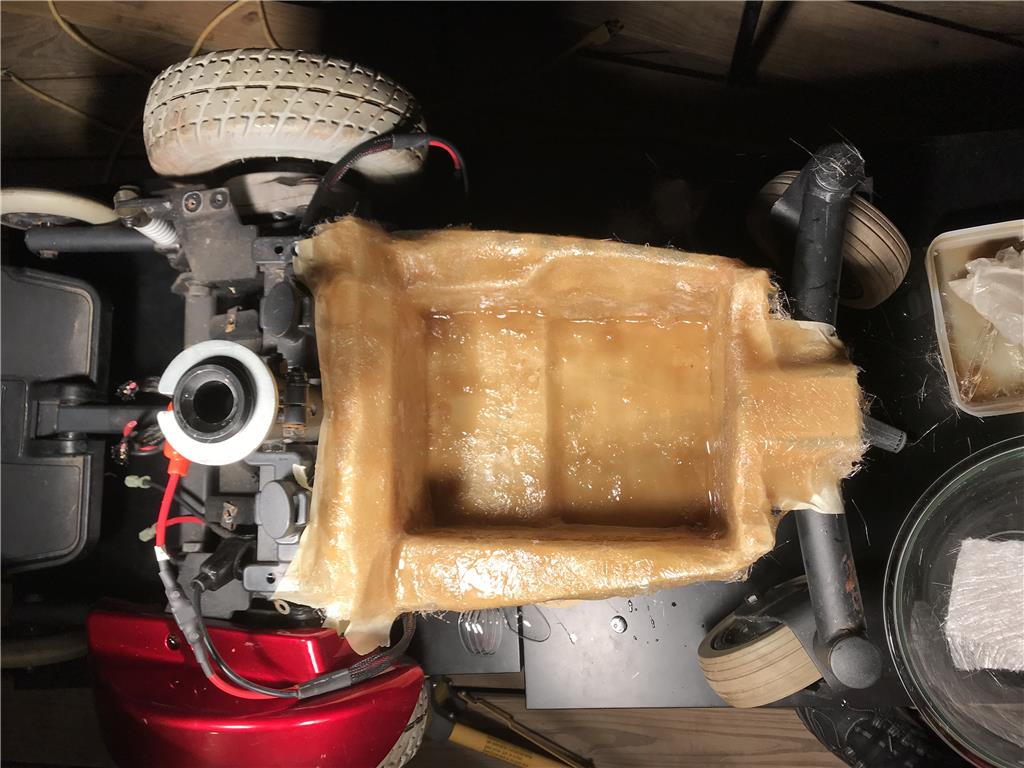
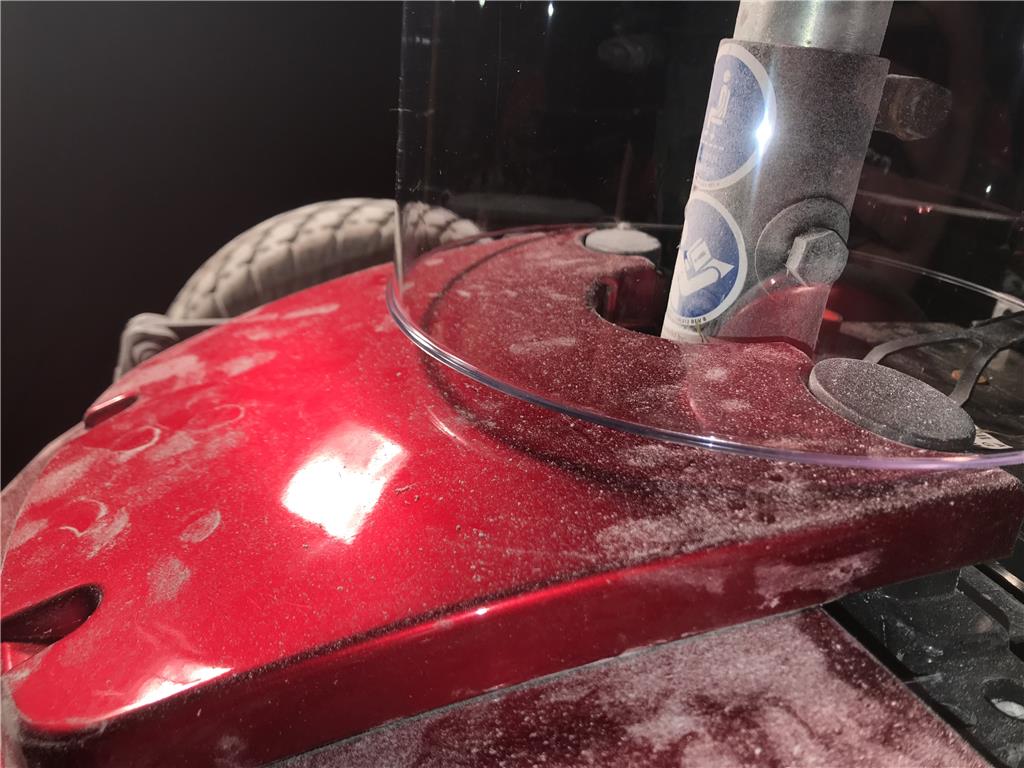
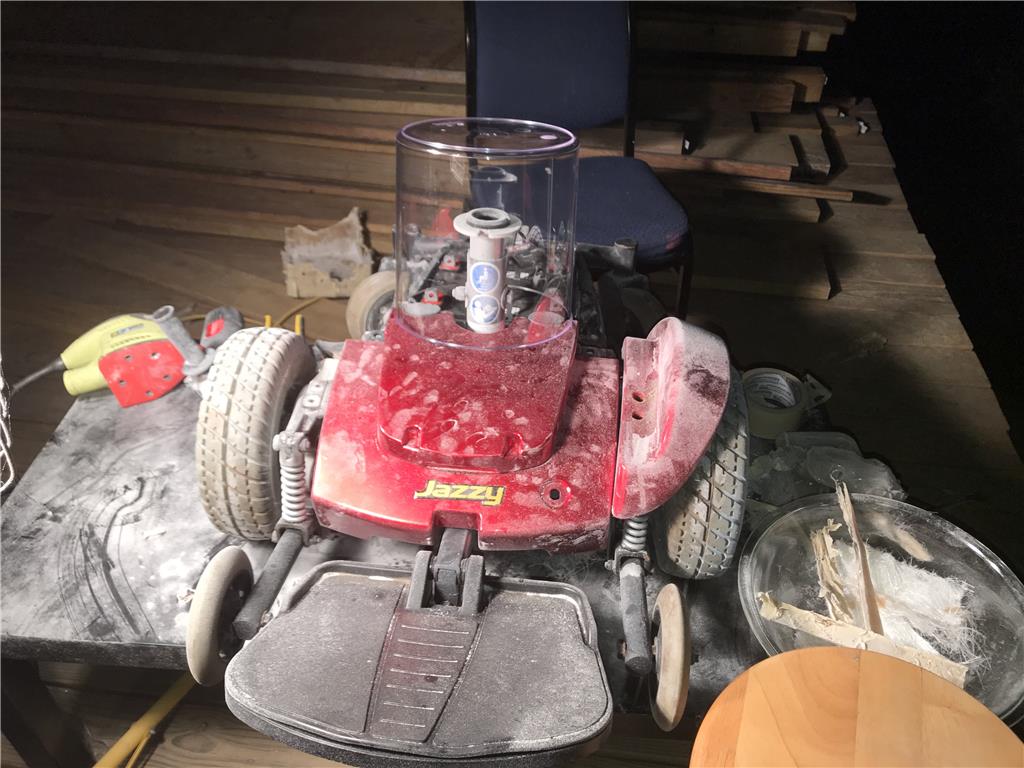
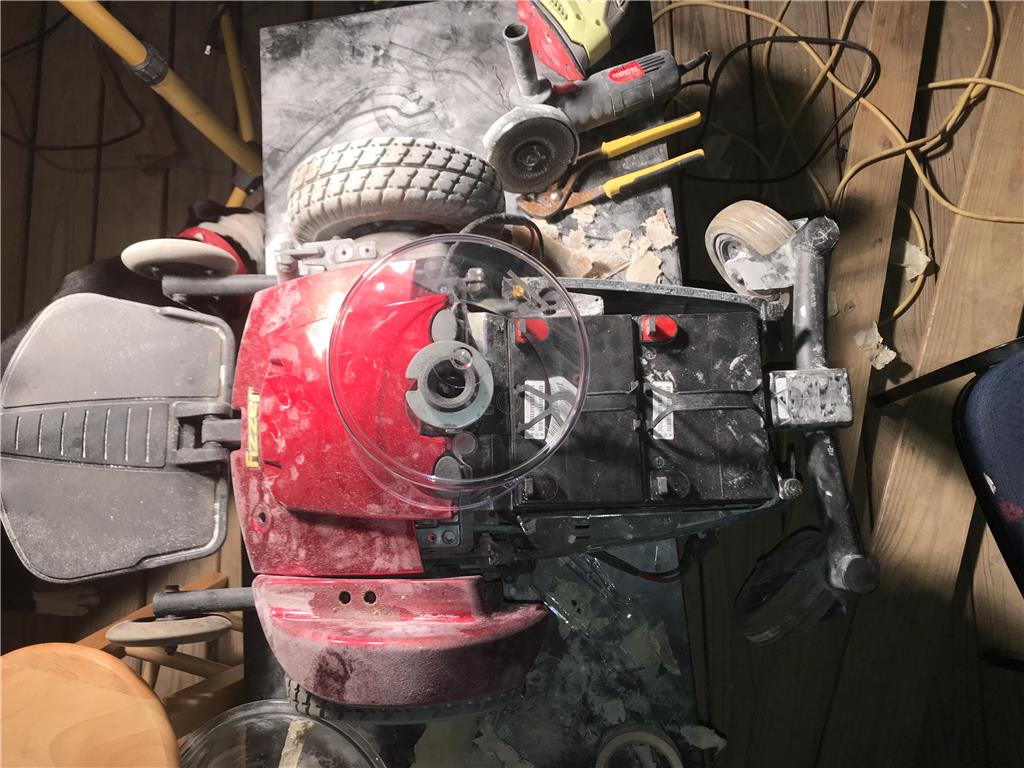
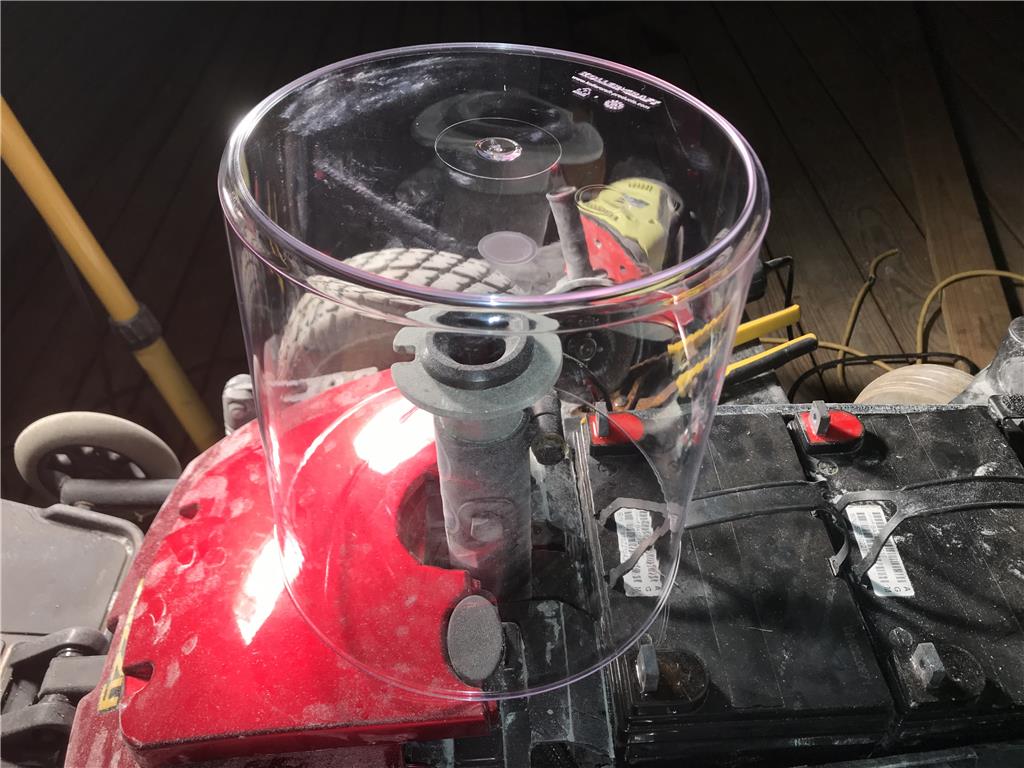
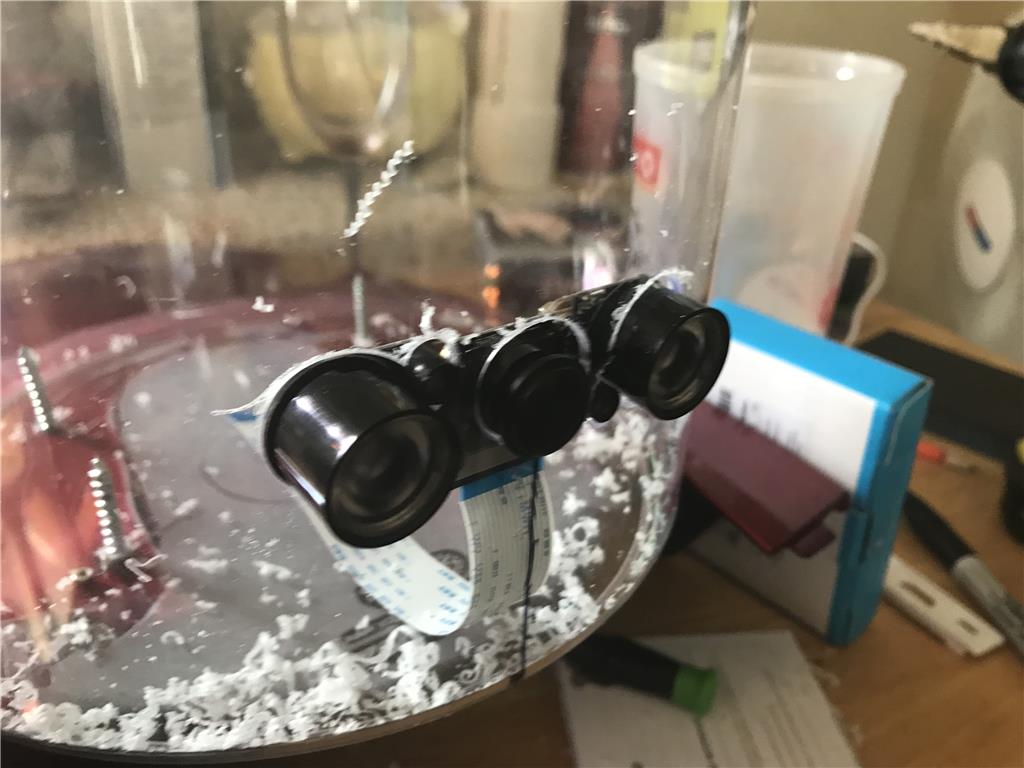
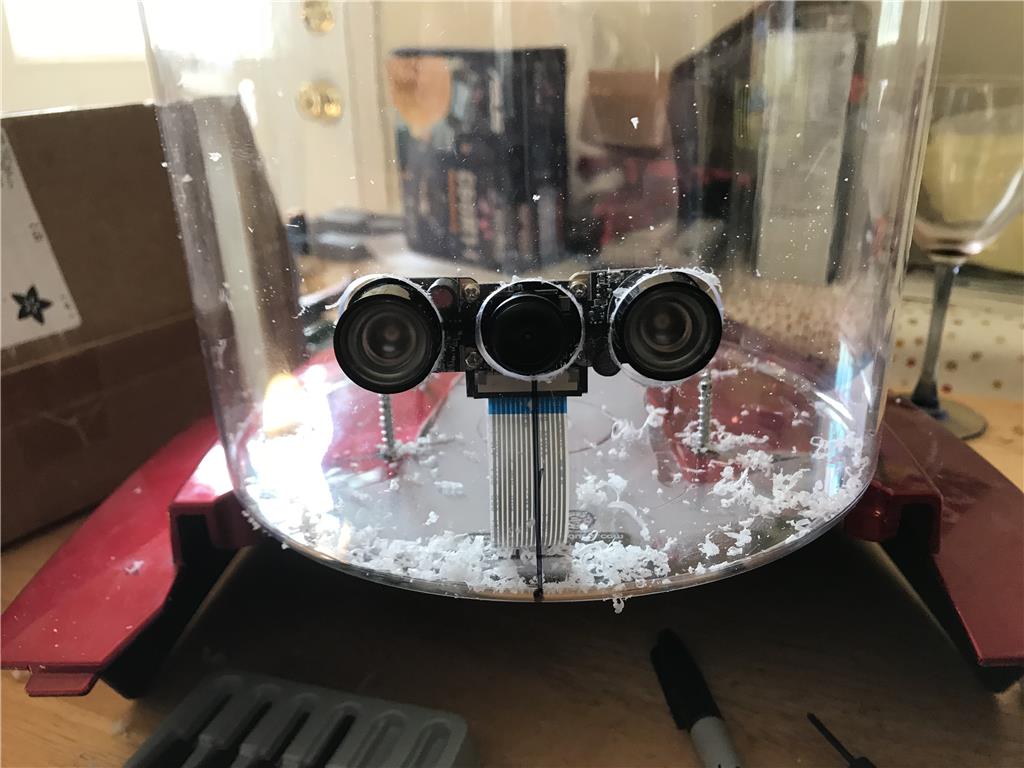
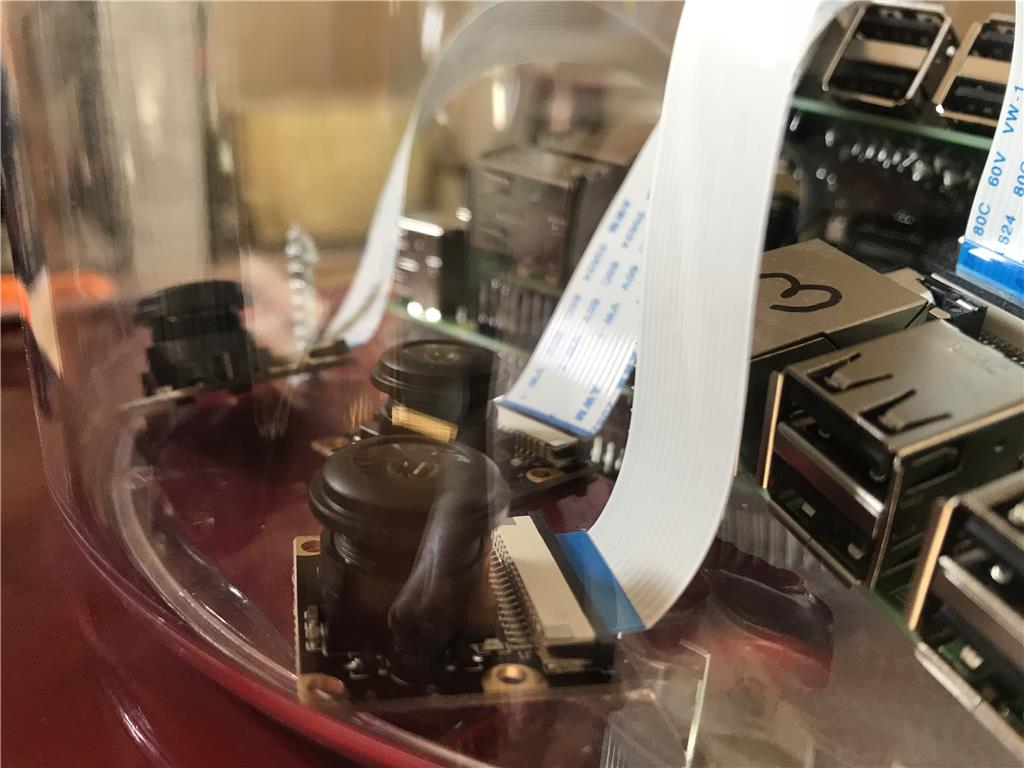
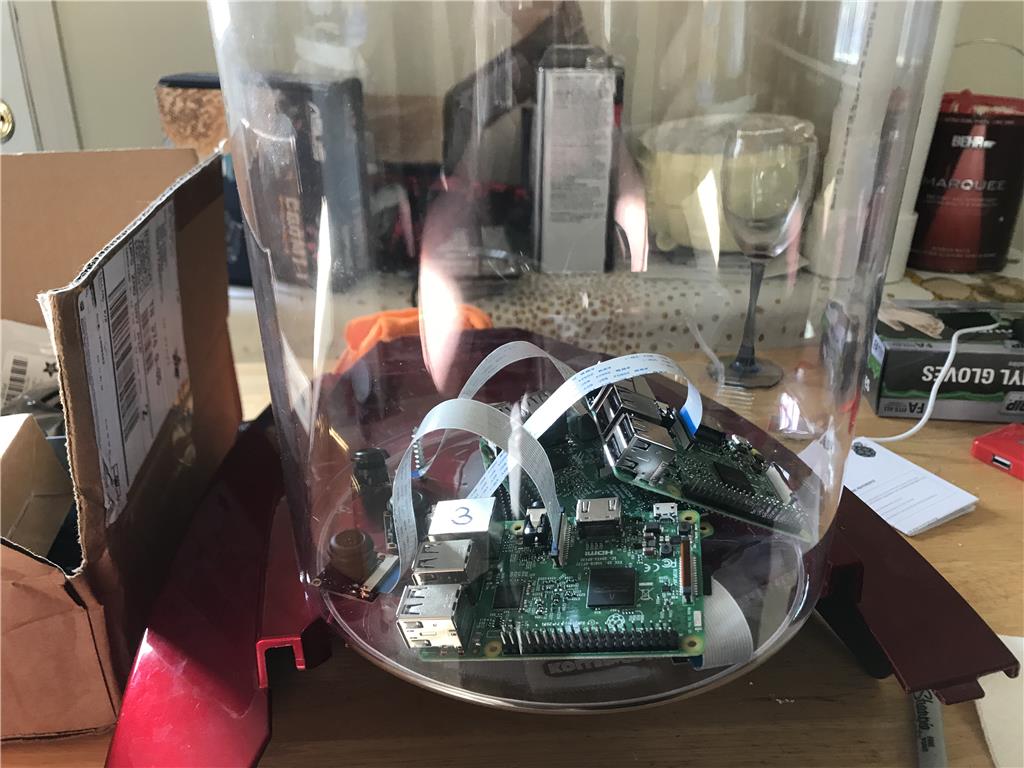
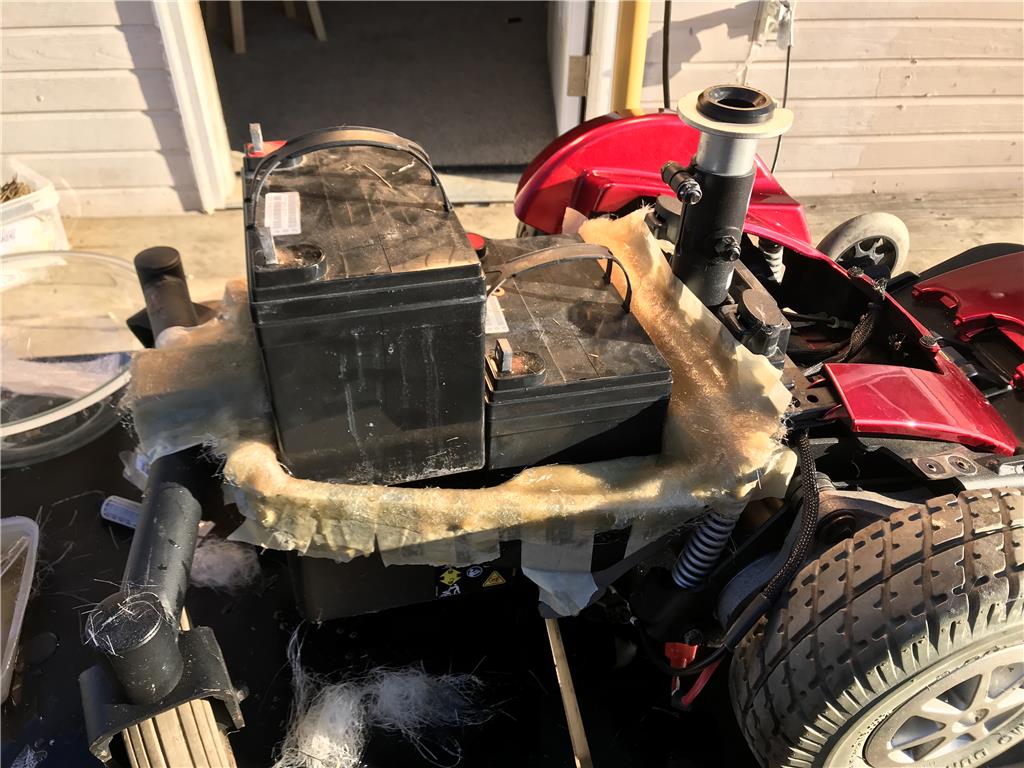
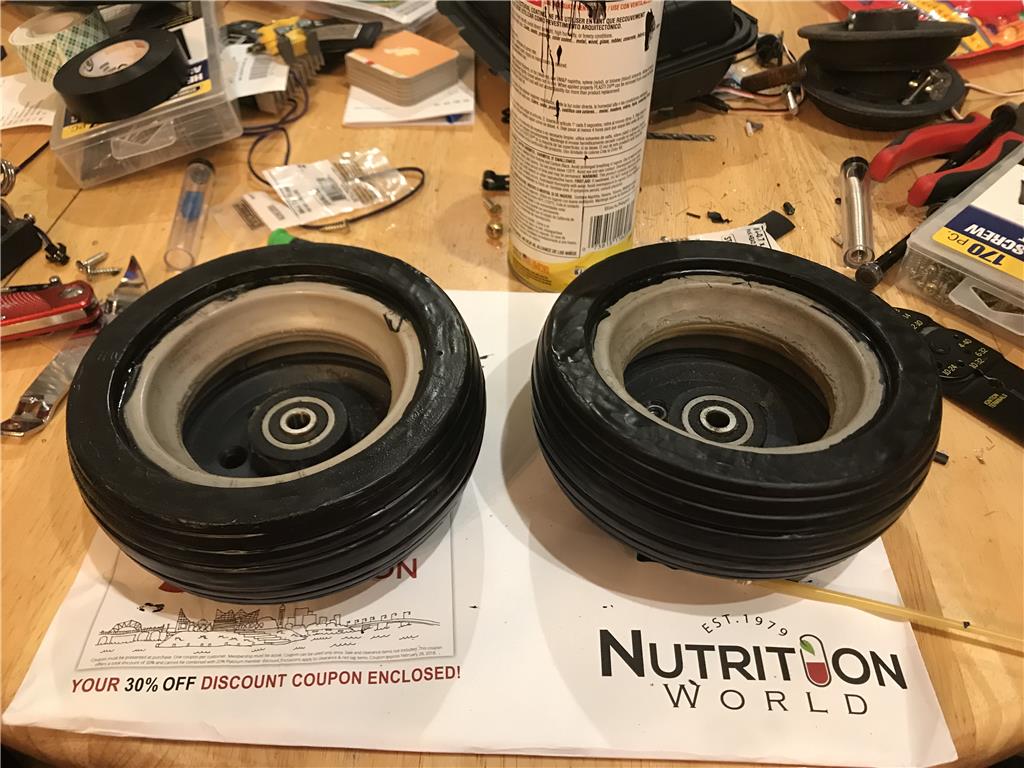
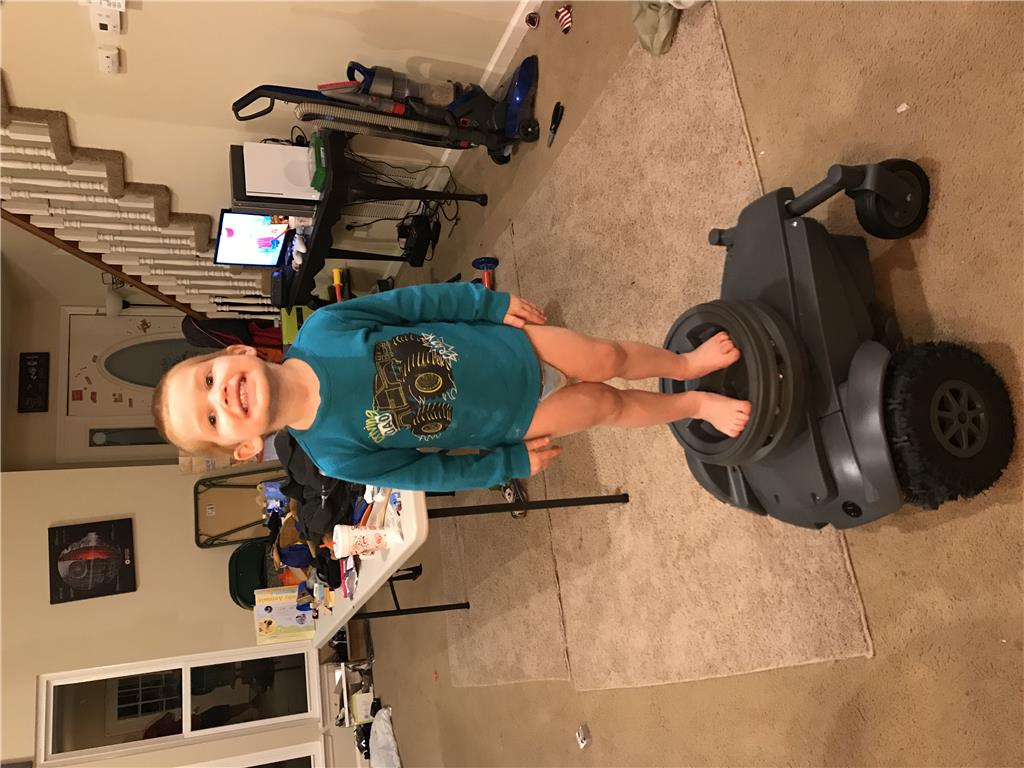
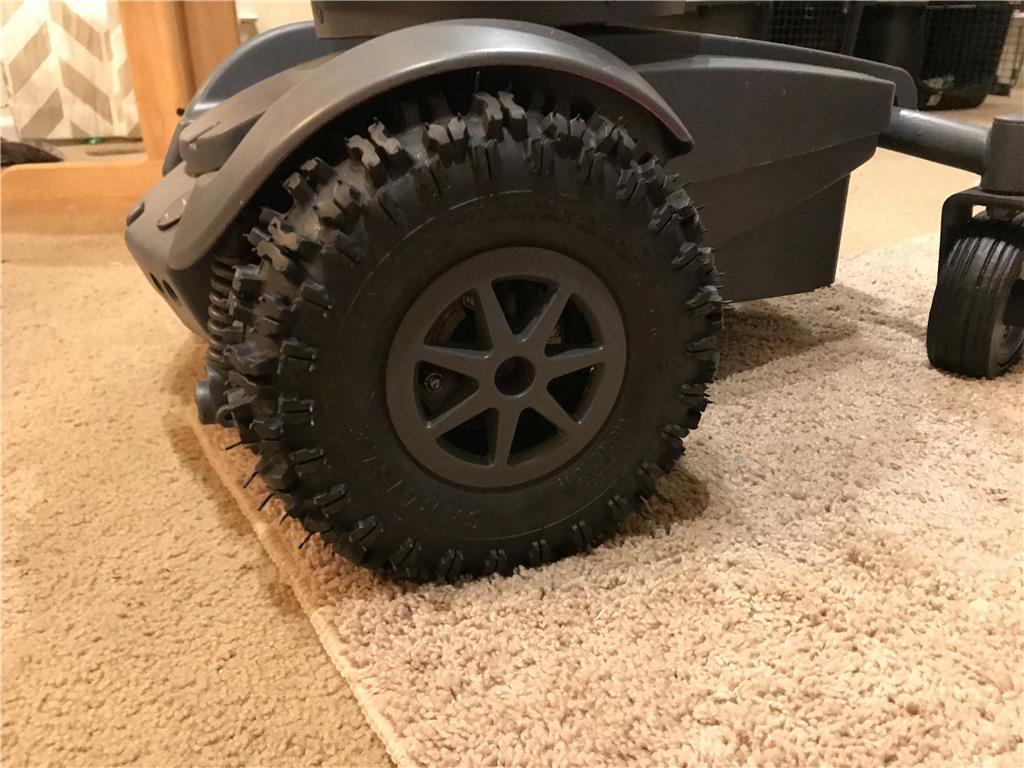
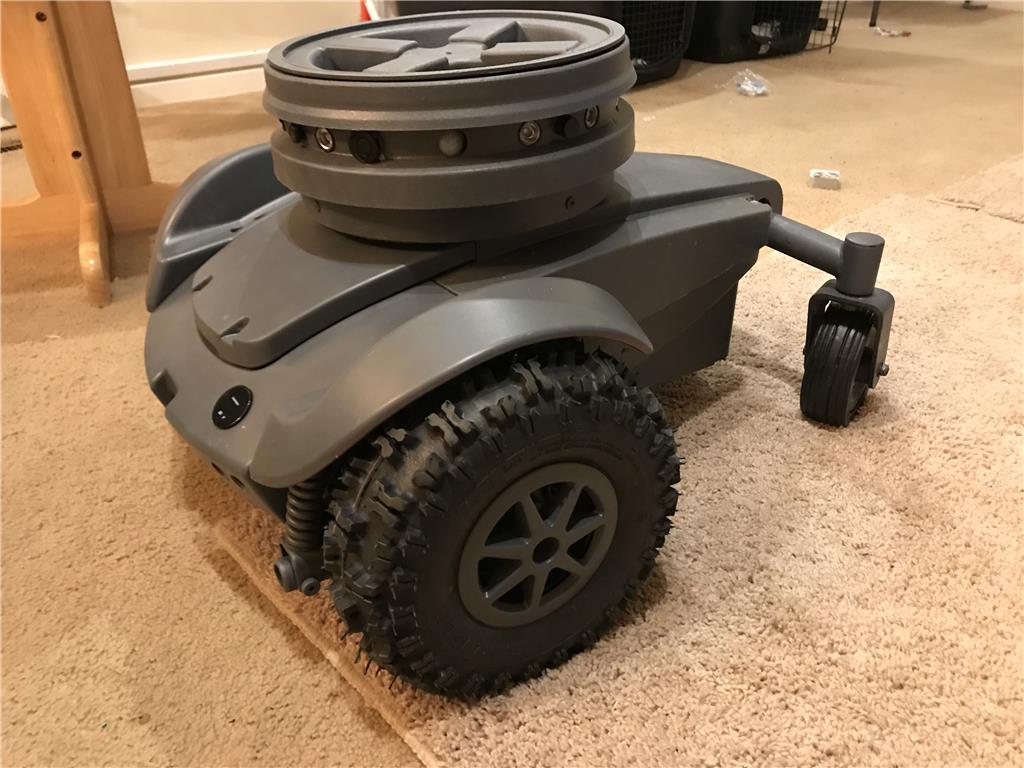
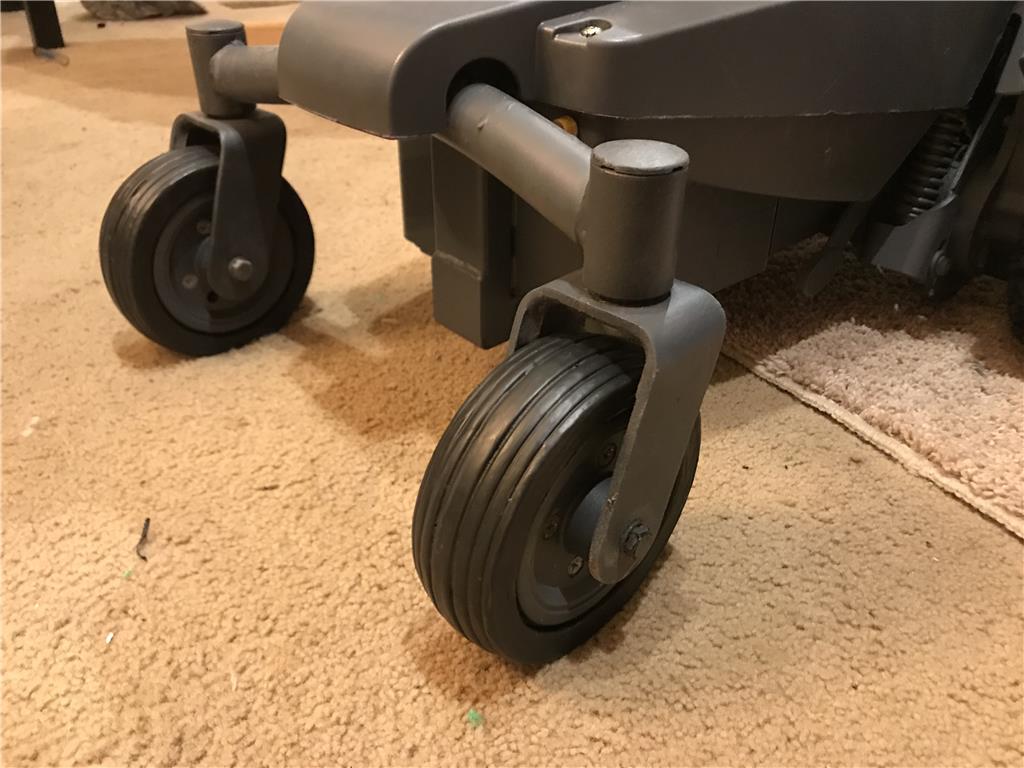
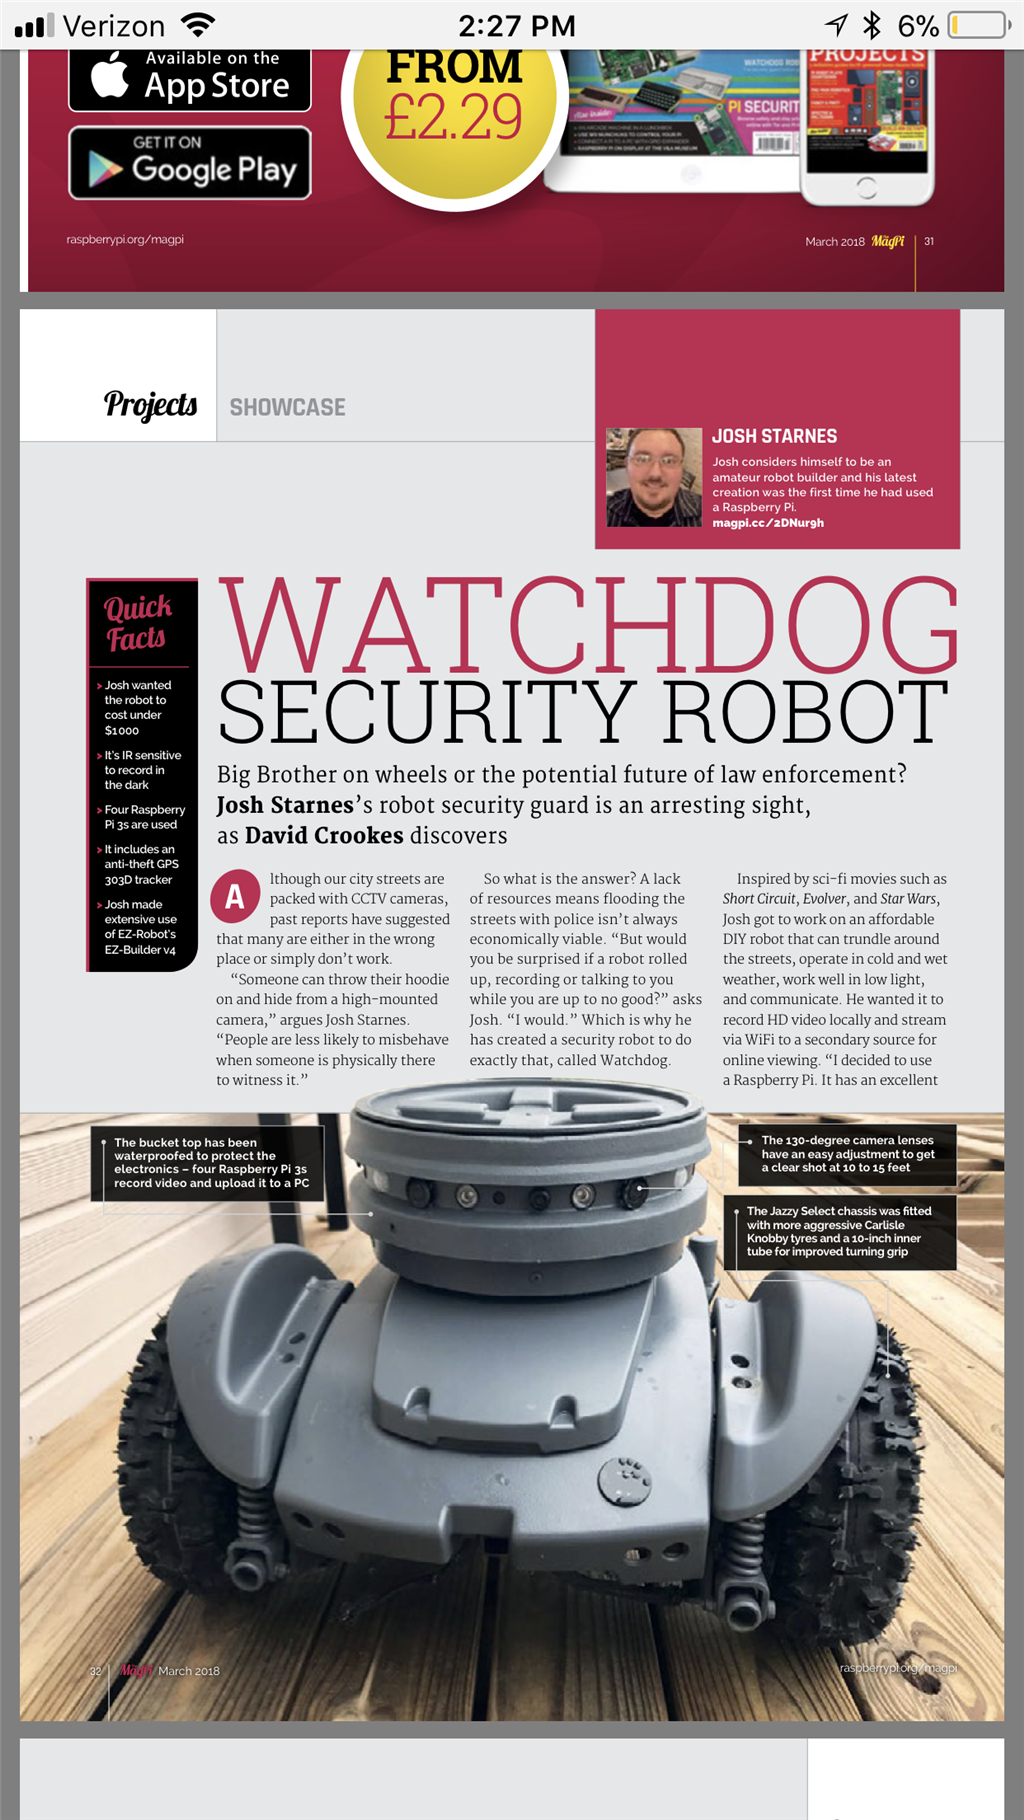
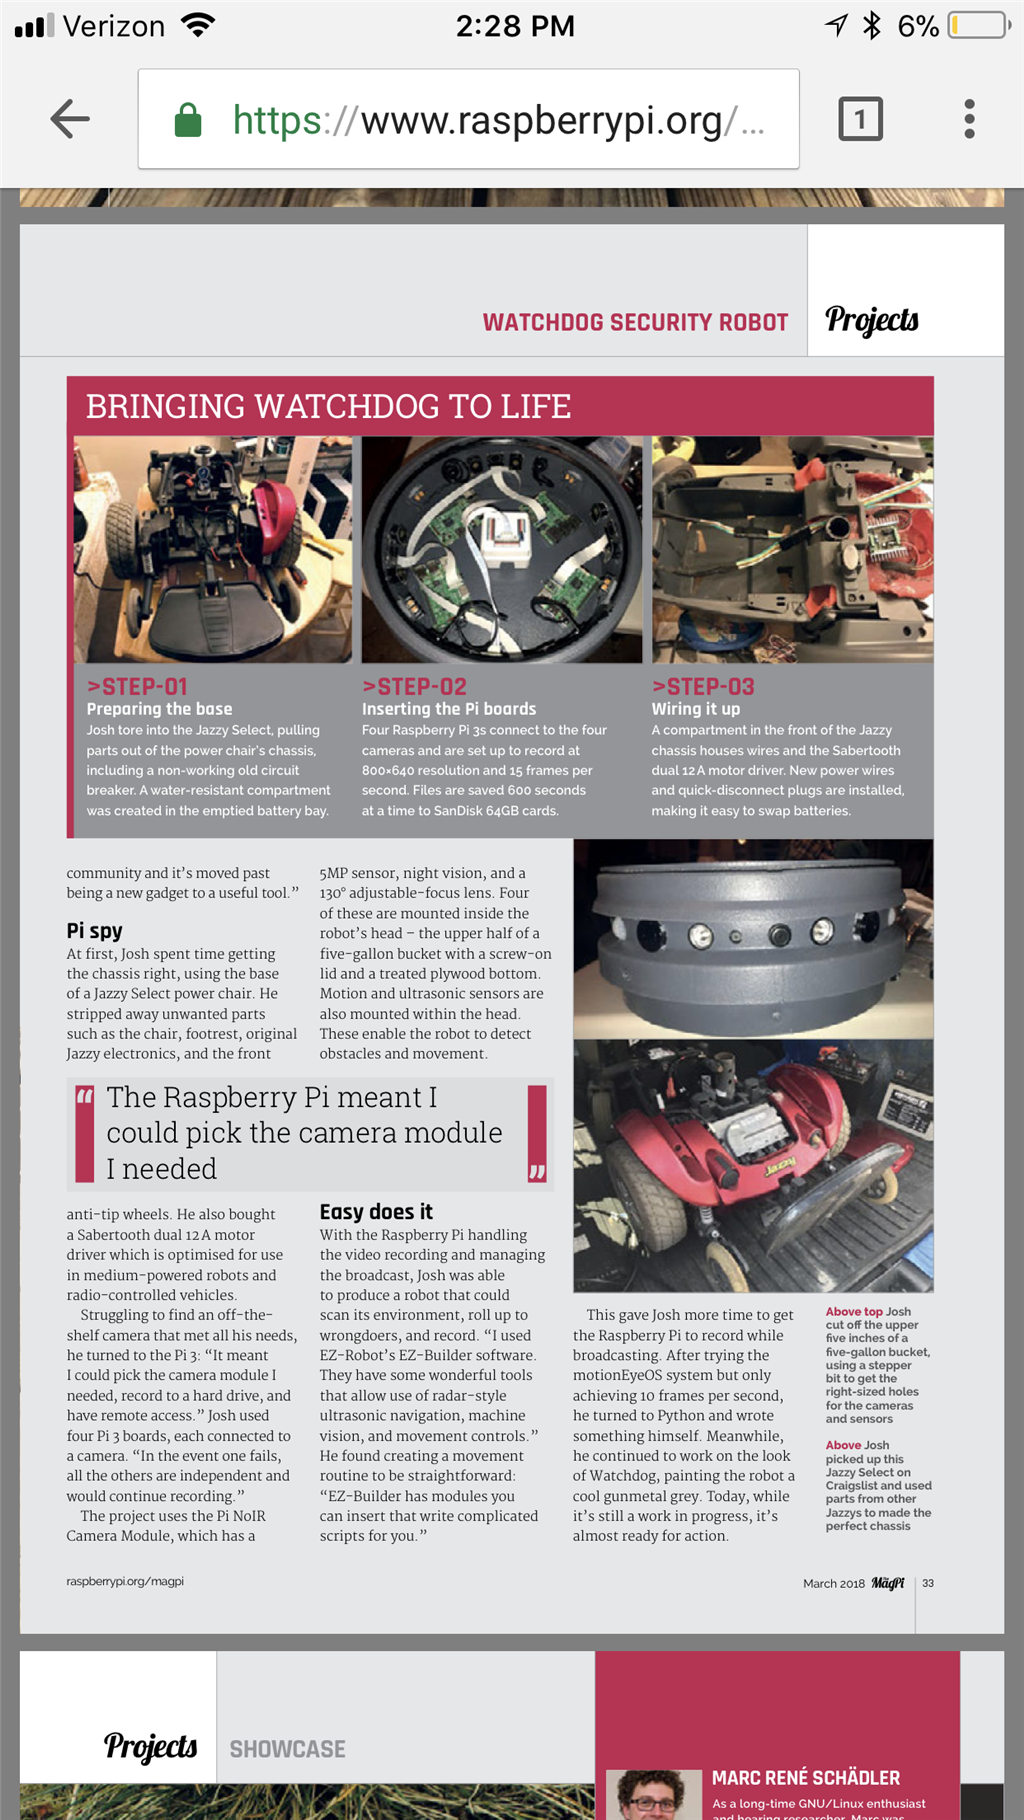
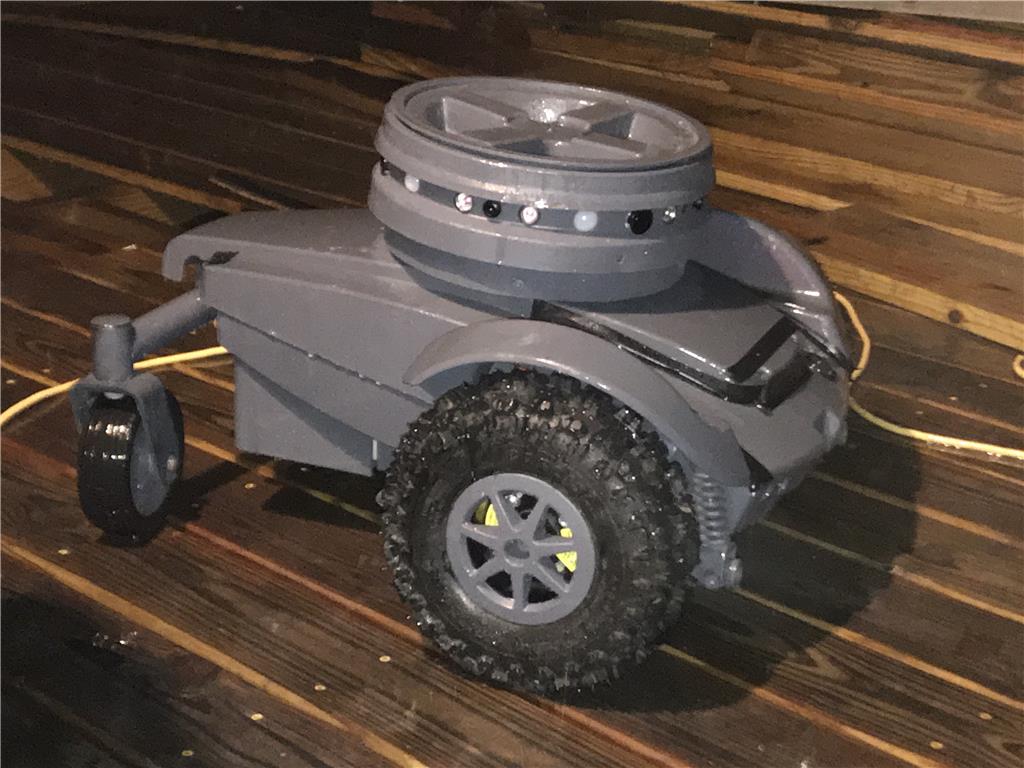
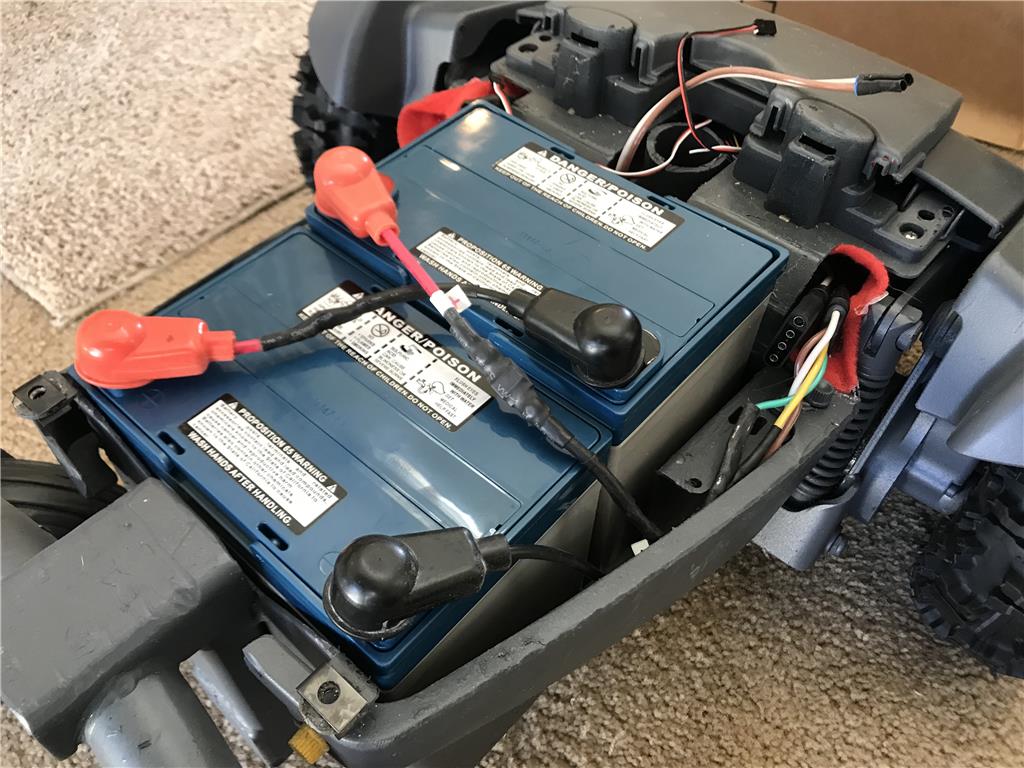
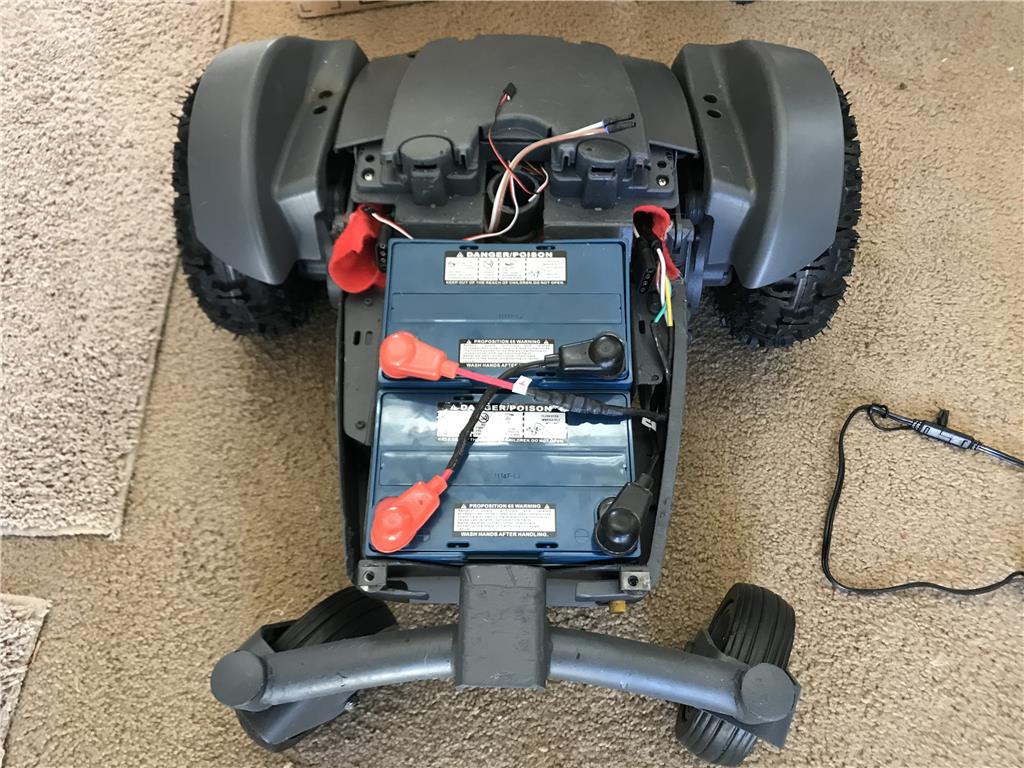
Here is the current look of this project, Super cool update, magpi magazine wants to feature this build with steps how it was done , !
By jstarne1
— Last update

Discover more robots
Tymtravler's Starting On Jac
Building JAC tracked rover with strong rubber tracks, stair-climbing ability and a beefy arm that can grip a beer;...
Sudo's Synthiam Humanoid Project
Custom 24-DOF humanoid robot nearing completion with planned EZ-B v4, wrists/head pending, leg cable extension and...

Mattbrailsford's Omnimc
Convert an Omnibot 2000 into OmniMC media center with Raspberry Pi (RaspBMC), RC control, EZ-Robot kit, screen, battery...

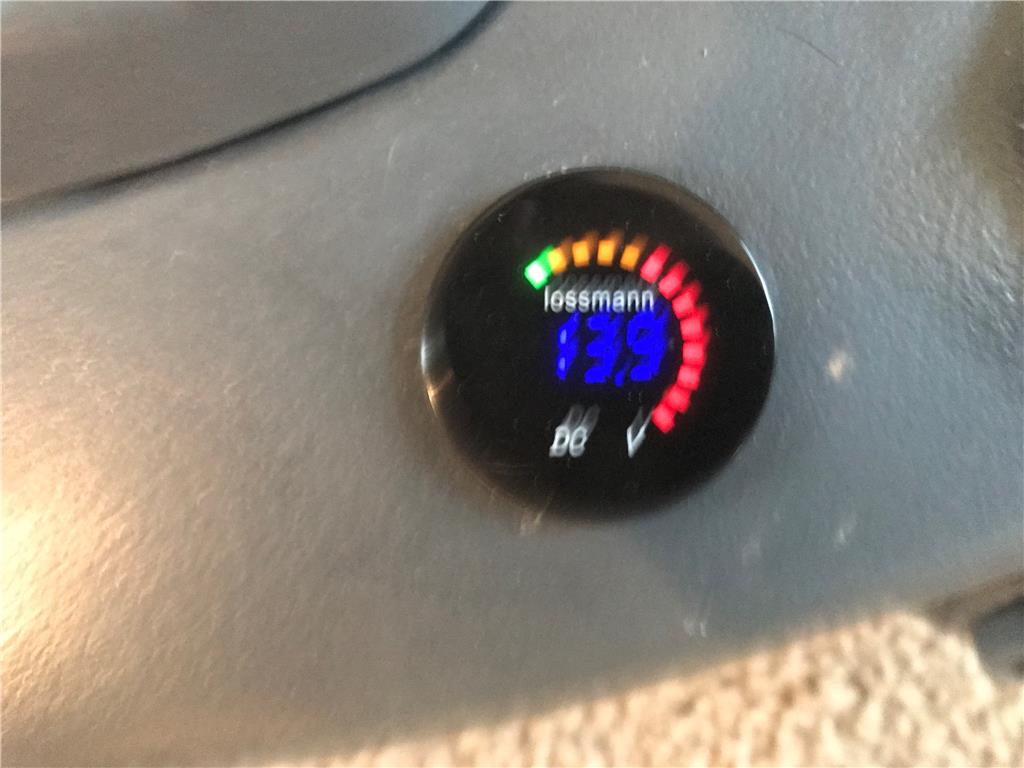
Sabertooth is on idle but powered on. The Robot is not moving for this initial test , I wanted to get some base numbers as most the time the Robot will watch and wait , it doesn’t run around continuously.
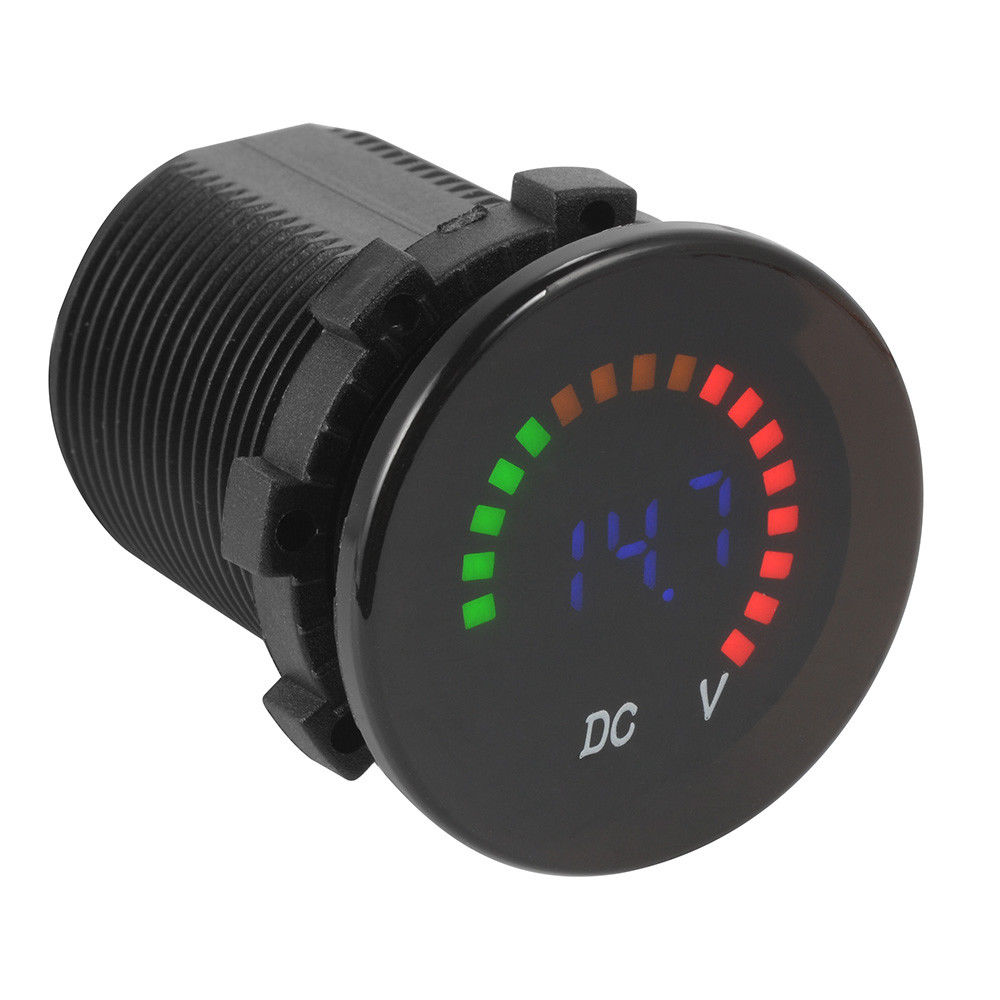
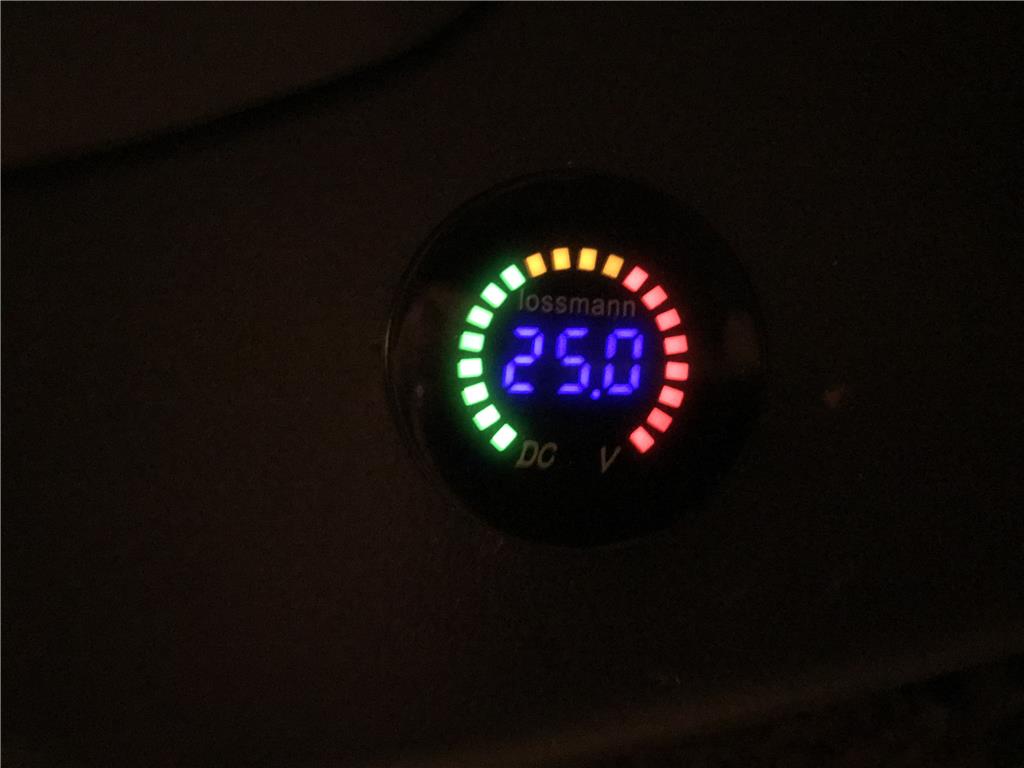
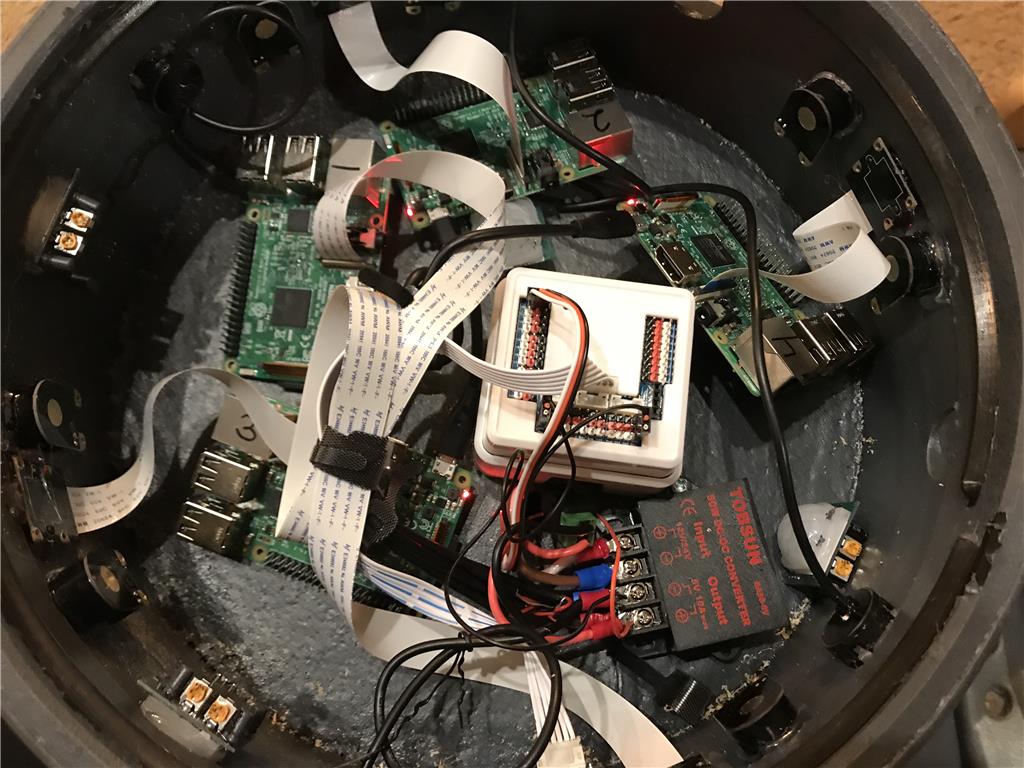
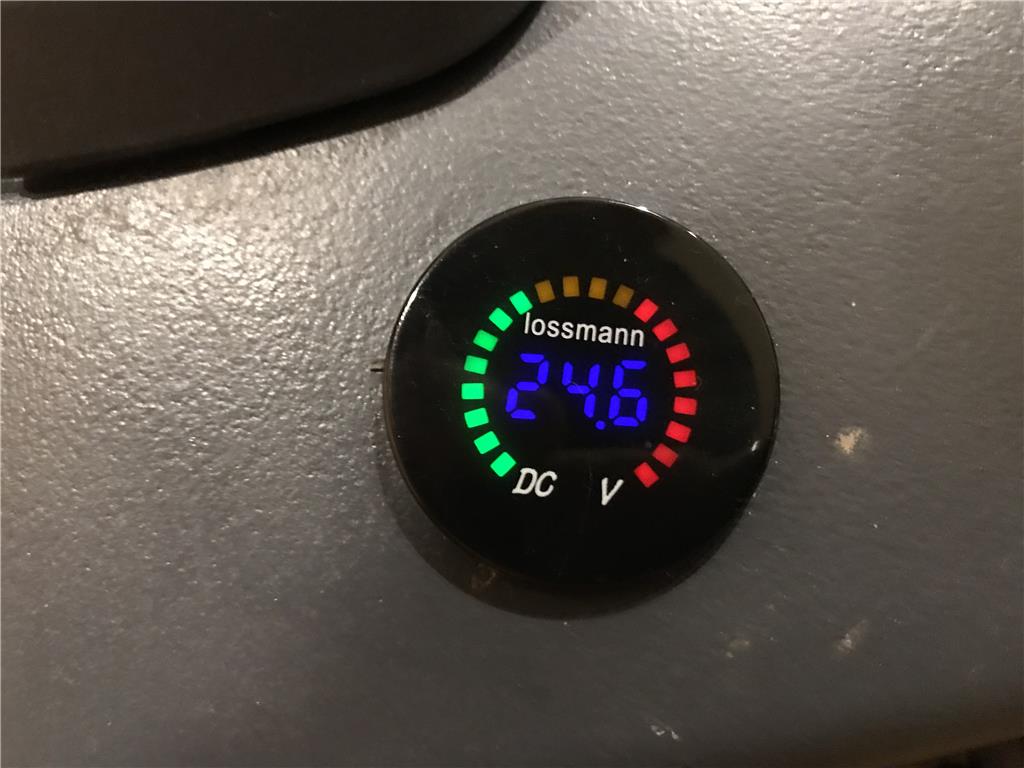
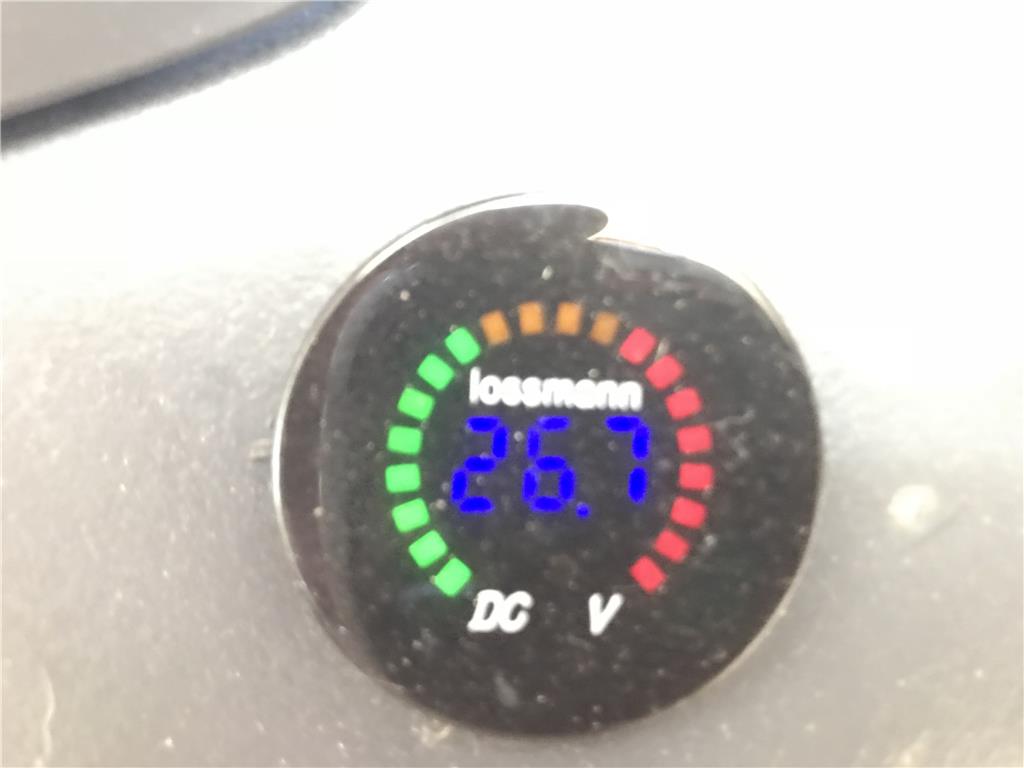
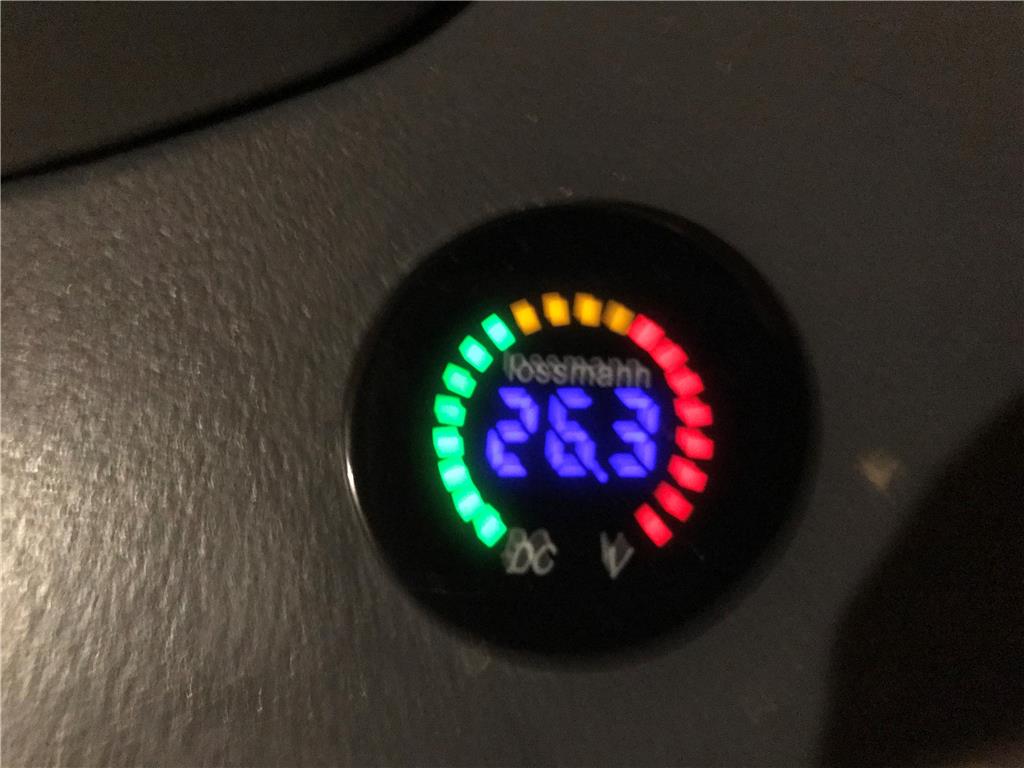
Ok, Update on the runtime test, the robot was idle but all the equipment except the IR leds ( which consume 24 watts max) , motion and ultrasonic sensors. You can see the pictures of the starting voltage and the end voltage. Doing research I found 11.8 is considered dead for a 12 volt battery. or 23.6 when two batteries are together. I notived after 24 volts the rate of drop increased and was quicky down to 14 volts for the combined batteries. Still enough to power the robot , but bad for the overall life of the batteries! So in the future I am considering 24 volts " dead".
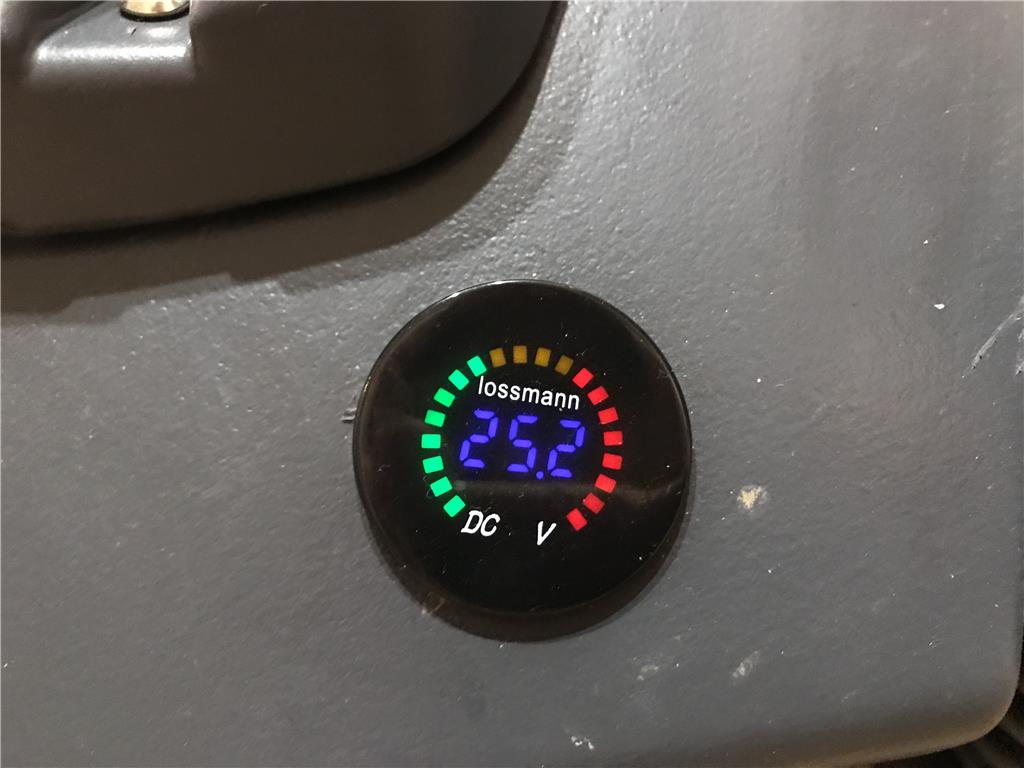
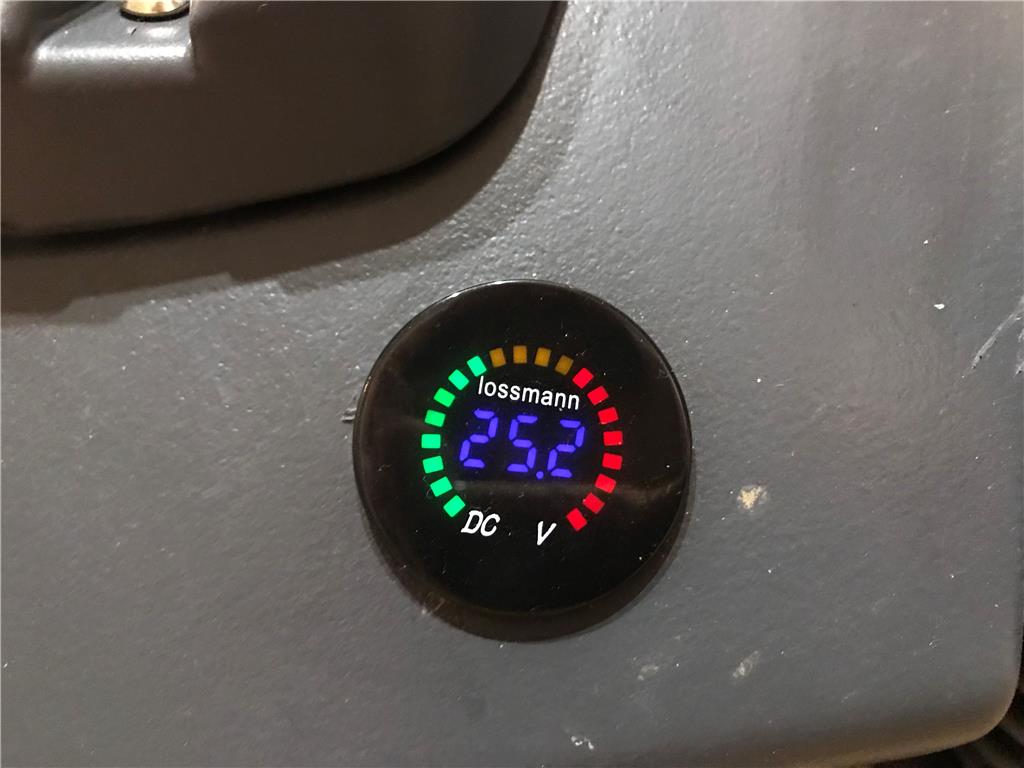
I wanted to test the battery longetivy, My goal is 24 hours without human intervention. Here is the starting voltage. ( I later found out that my batteries were not full when I started)
25.2 apparently is not 100 percent full, maybe these batteries were being broken in.
Excellent news ! After 24 hours runtime I still have battery life left.
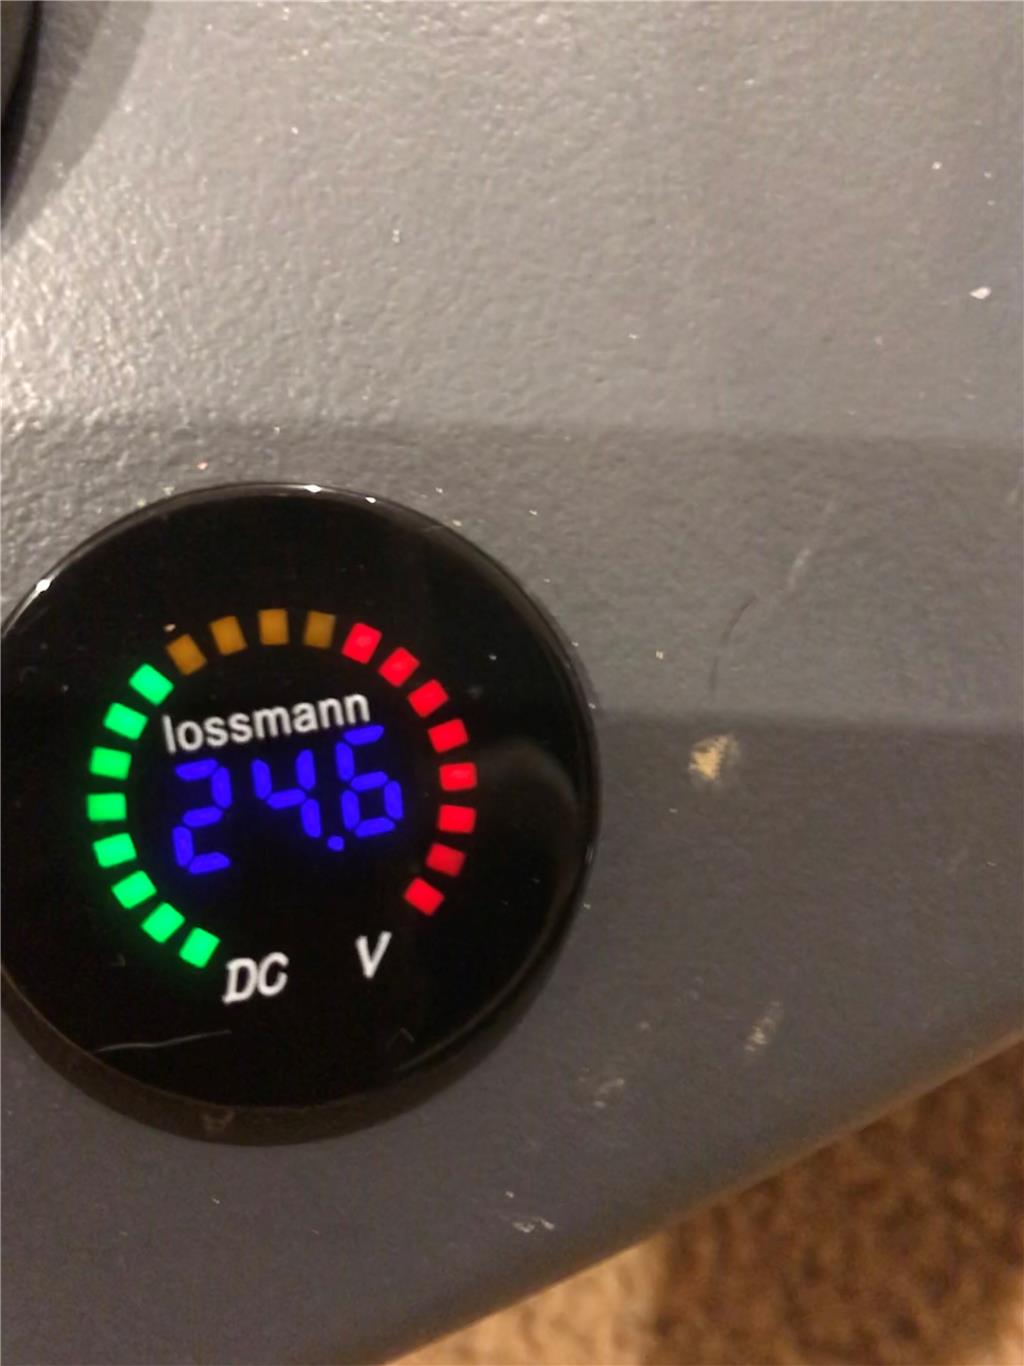
24.6 volts from the 25.2 starting voltage. That is an average of .025 volts drop per hour.
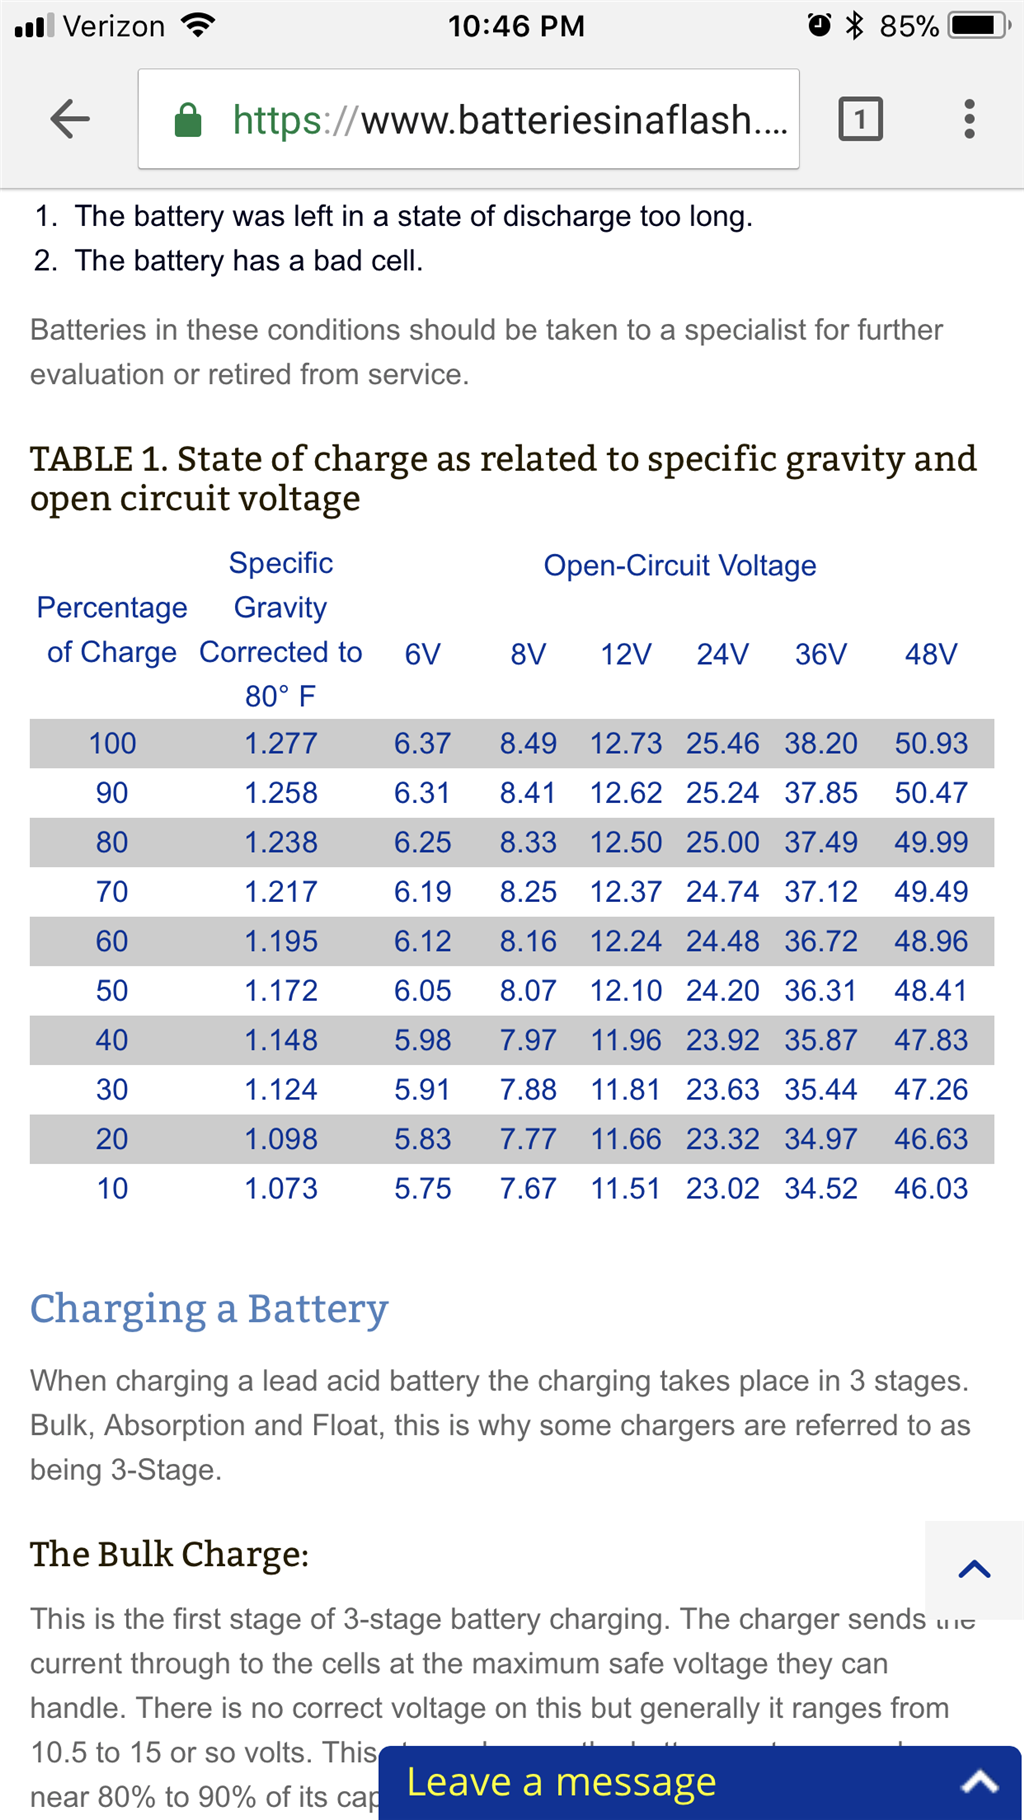
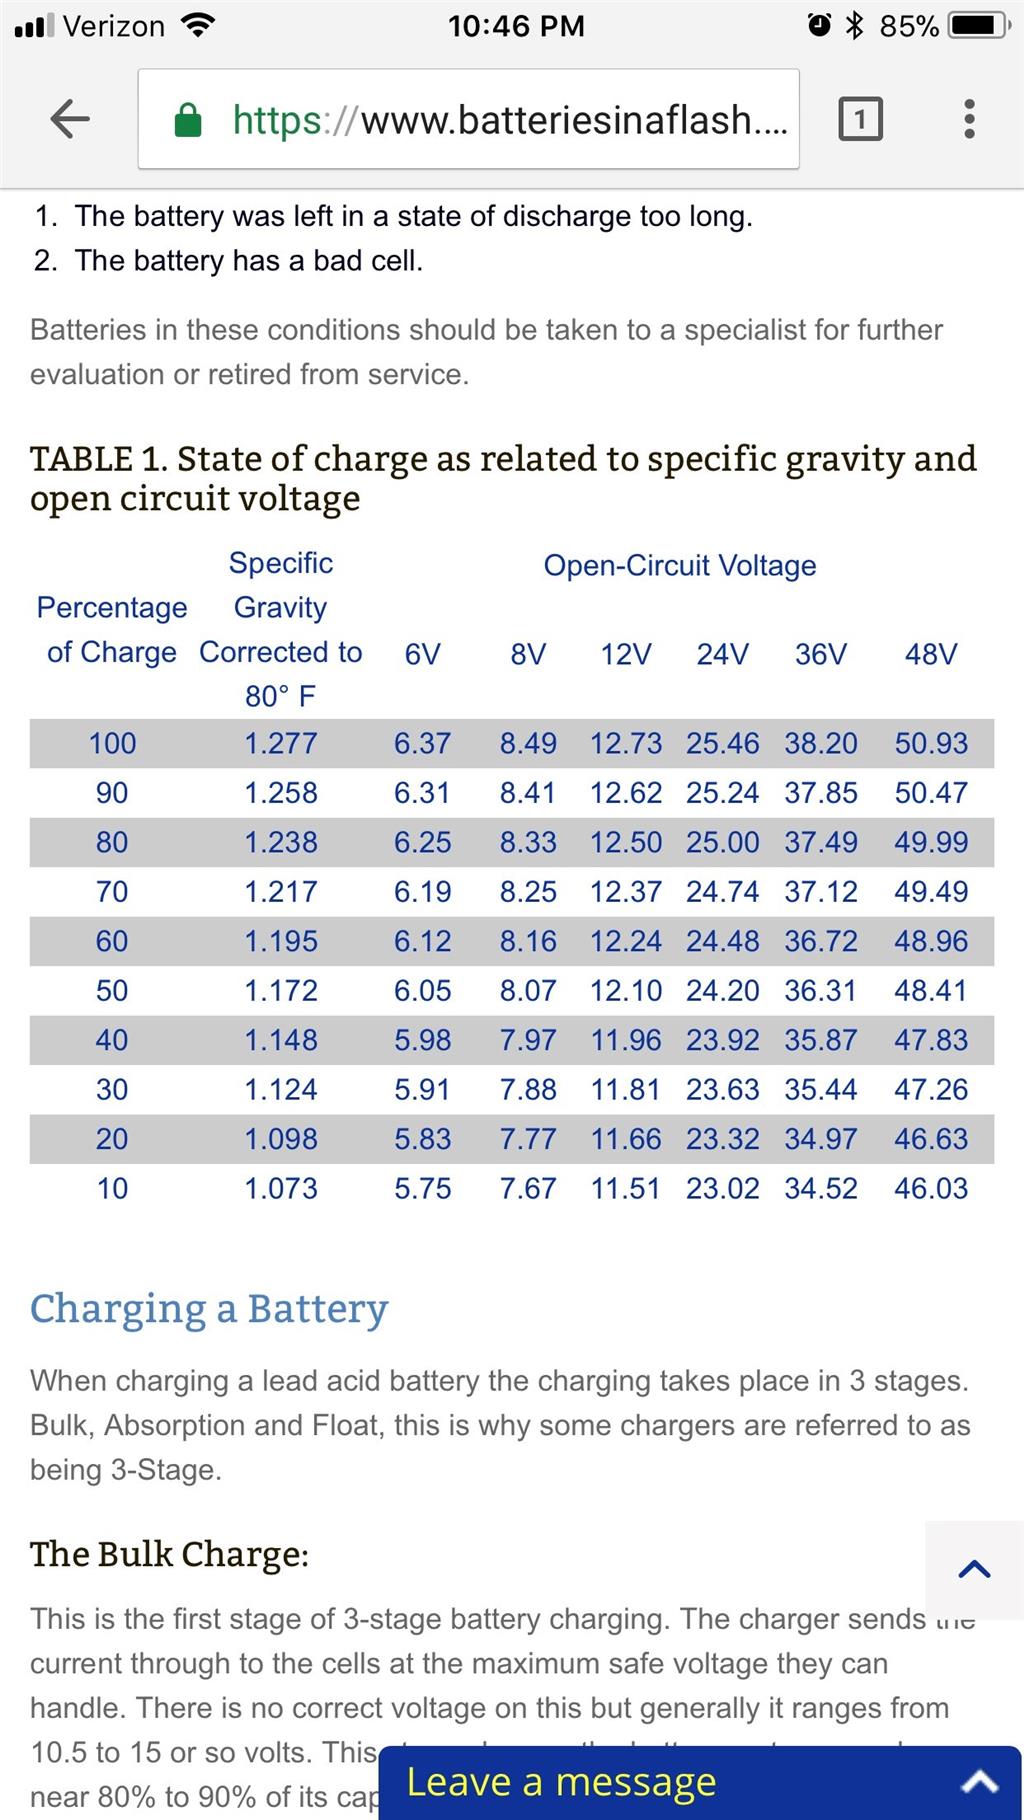
Here is a reference chart I am comparing to for the battery capacity, take in mind I am running 24 volts.
after about 32 hours I was at 24 volts even but I wanted to see if I could make it to an even 48 hours. I pulled the plug on the battery for recharge at 42 hours.
I charged both batteries on two 3 amp chargers for 12 hours and now they read a higher combined voltage than before! So apparently when I started this test I was only at about 80-85 percent battery capacity.
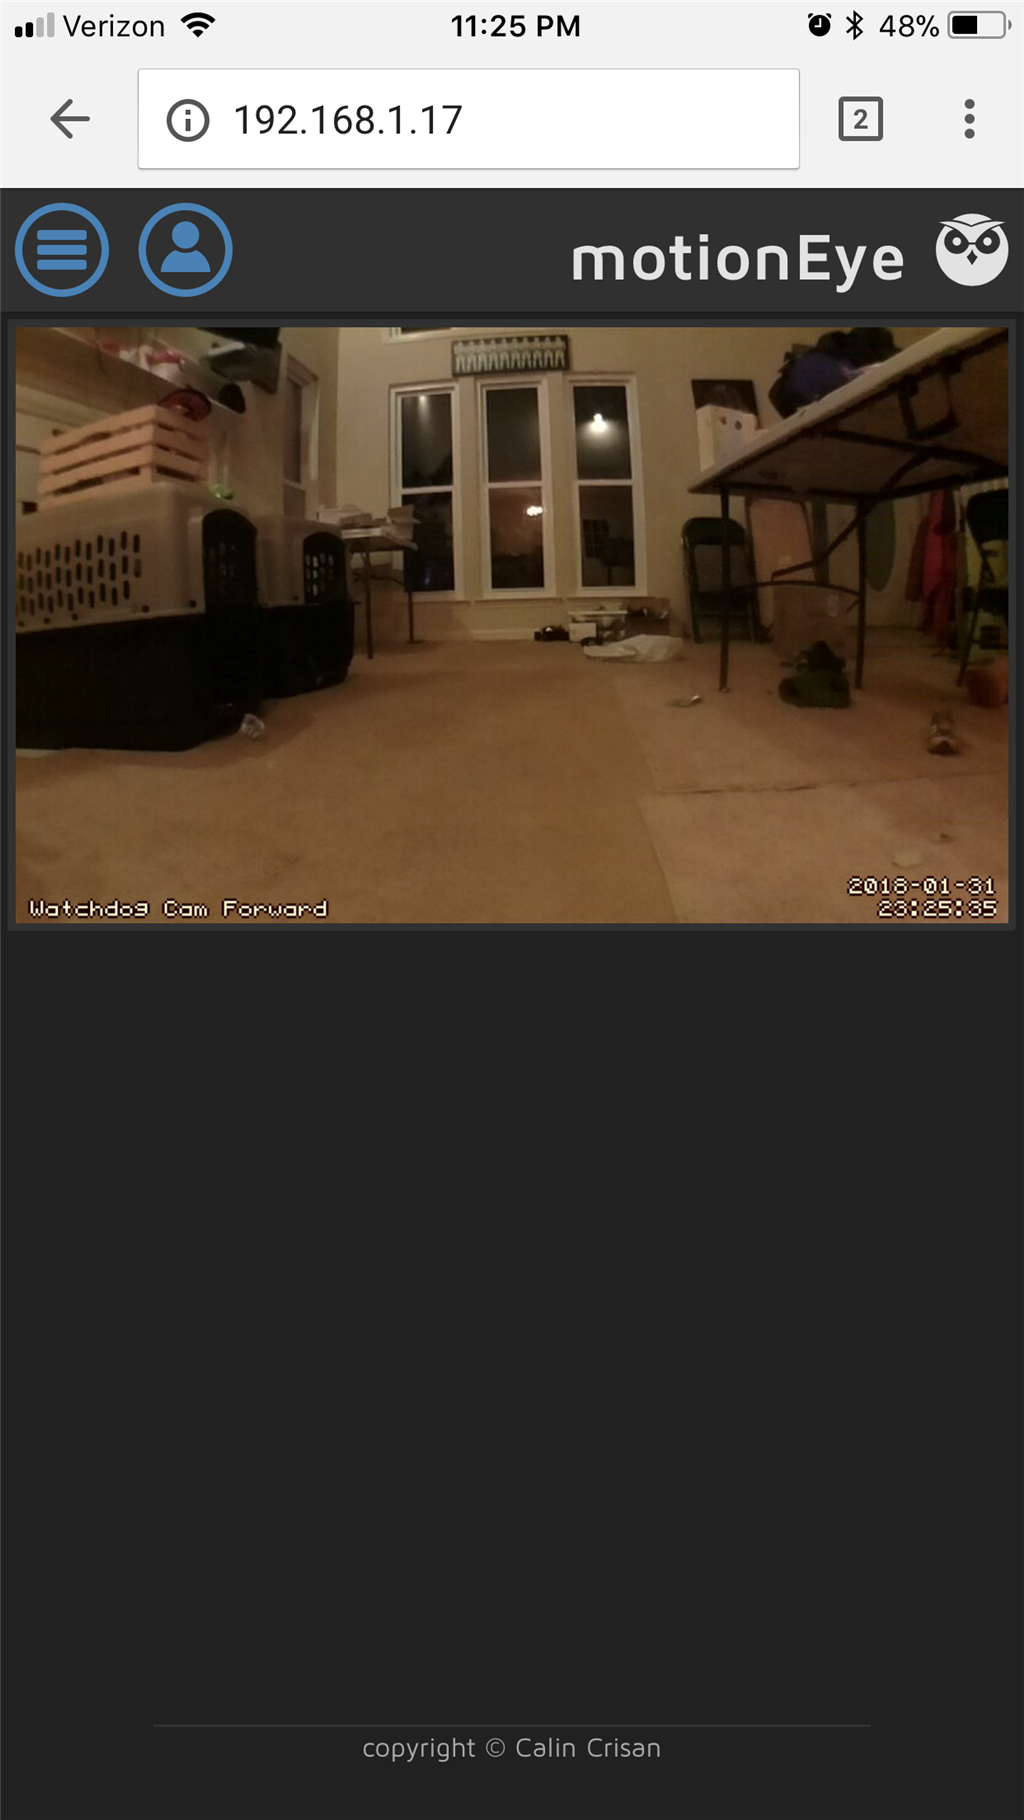
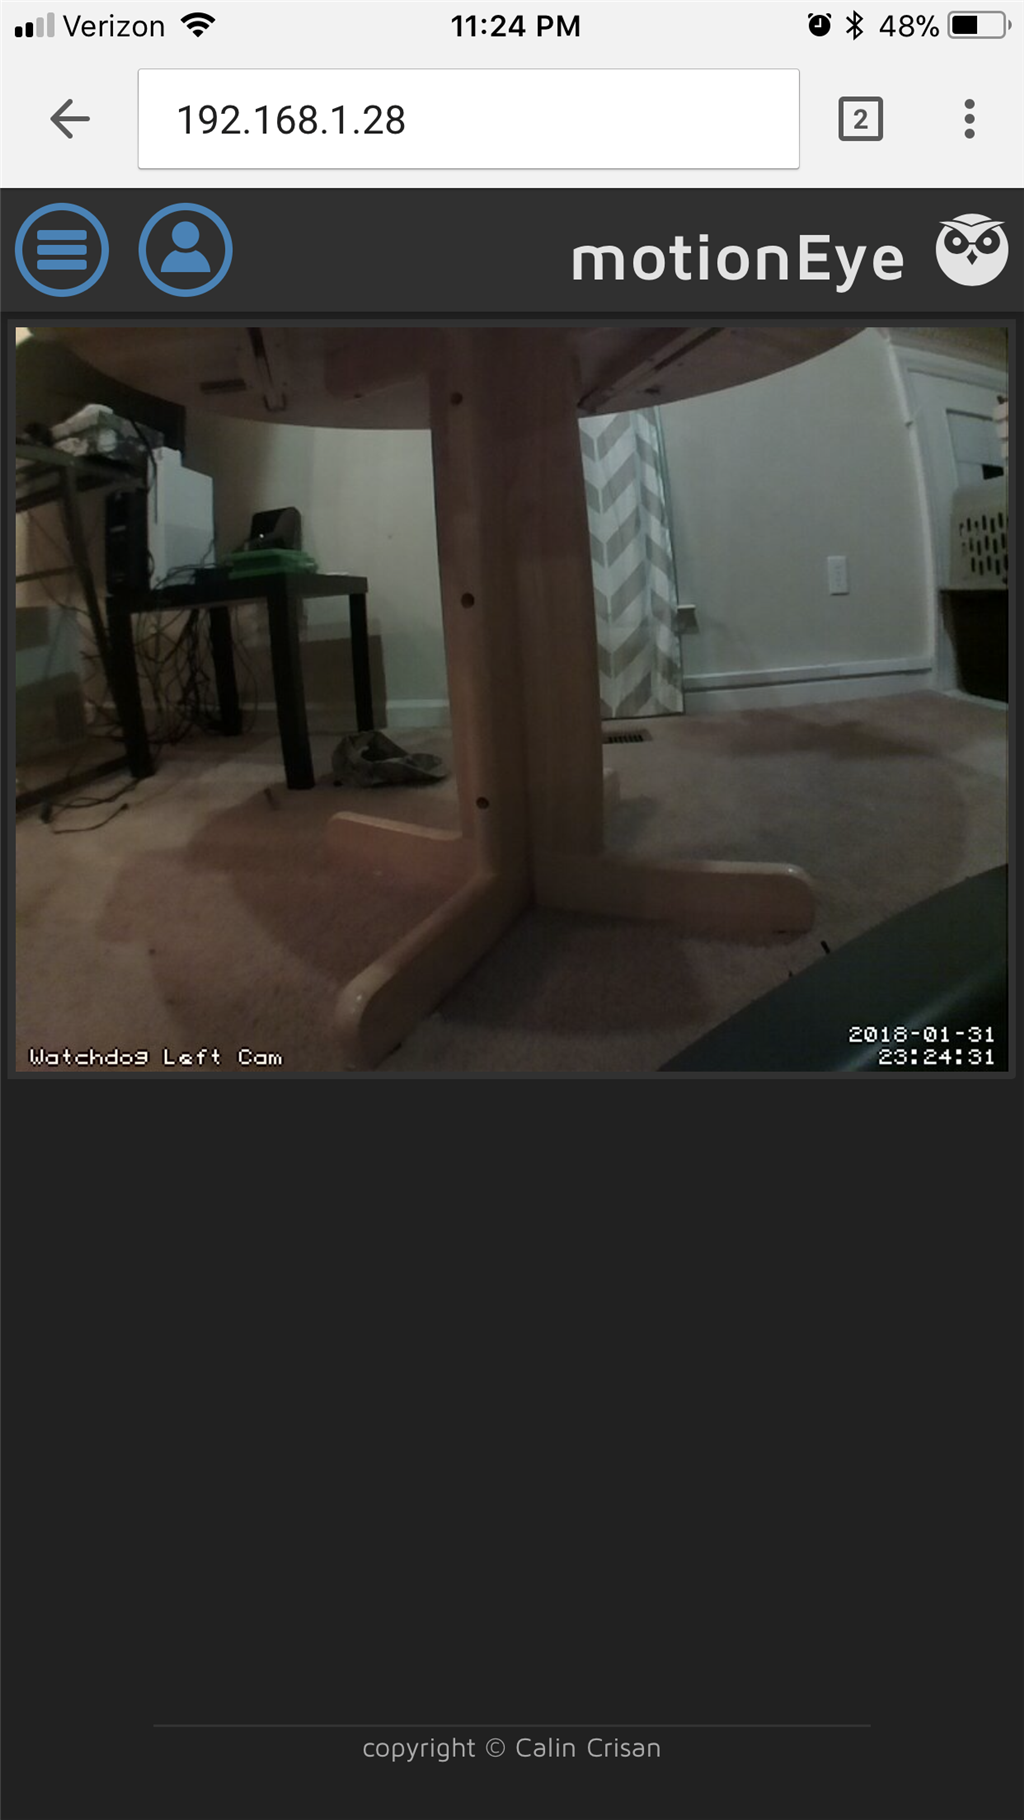
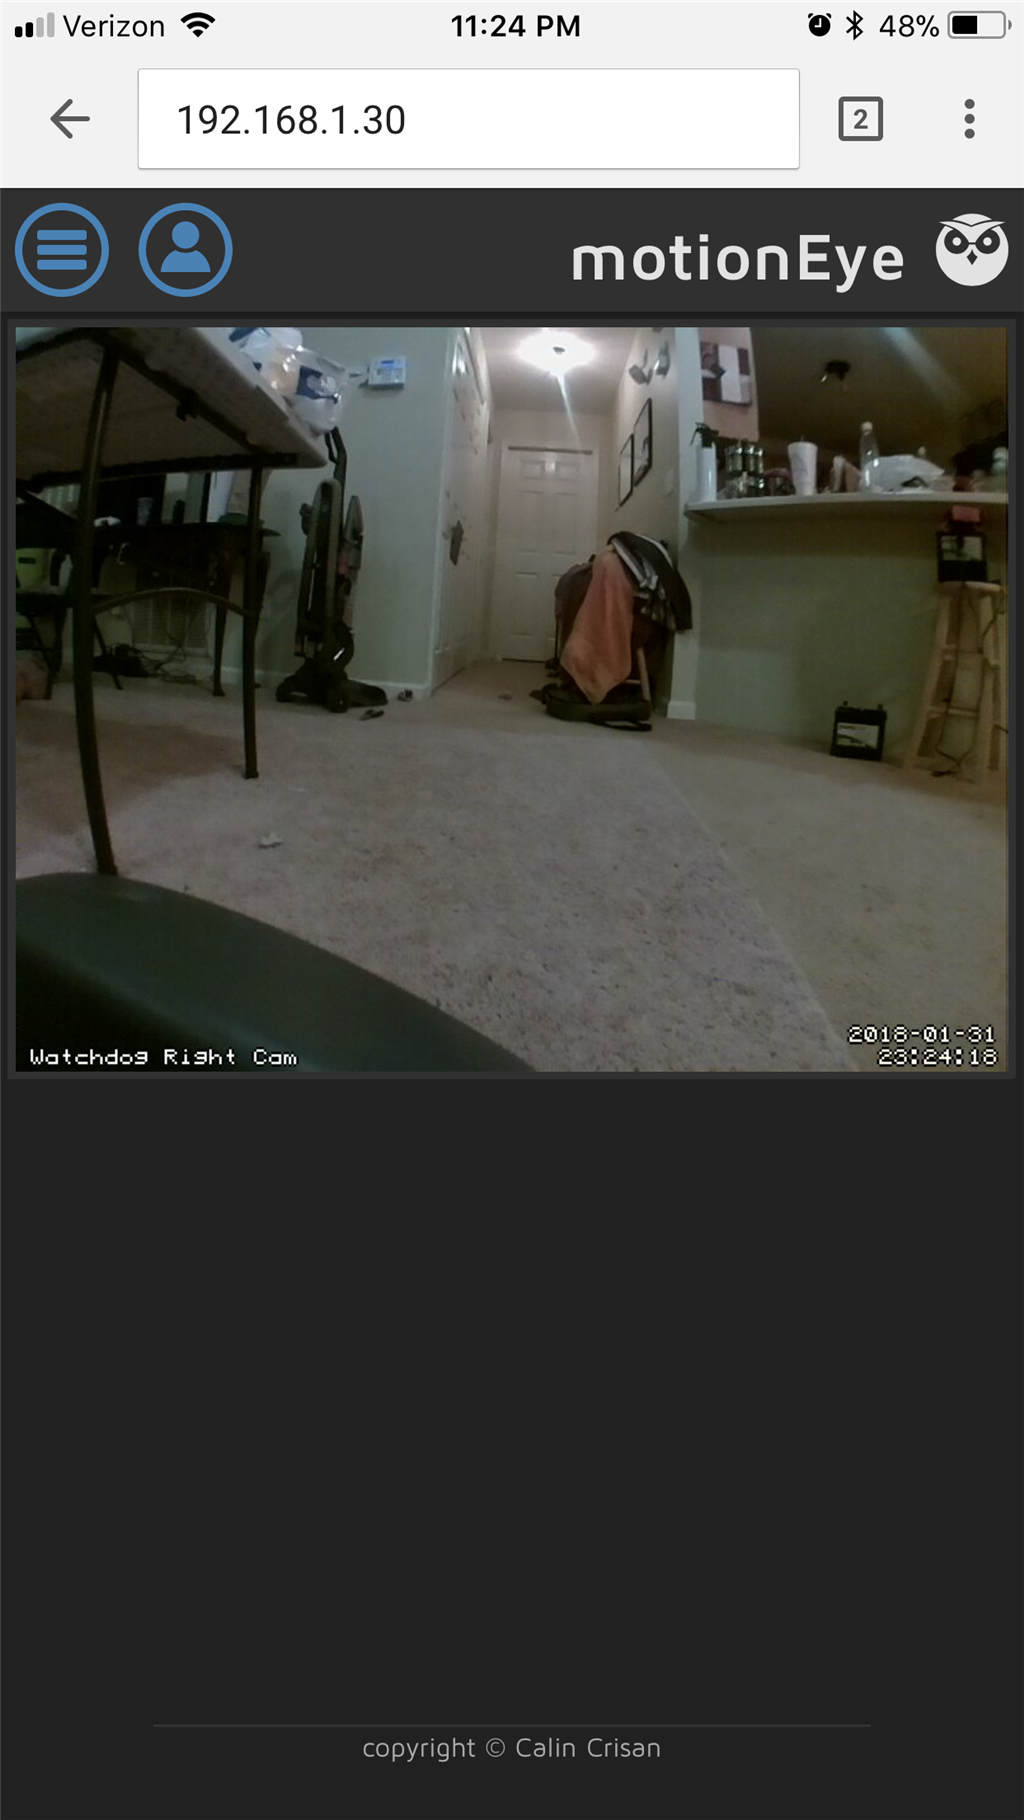
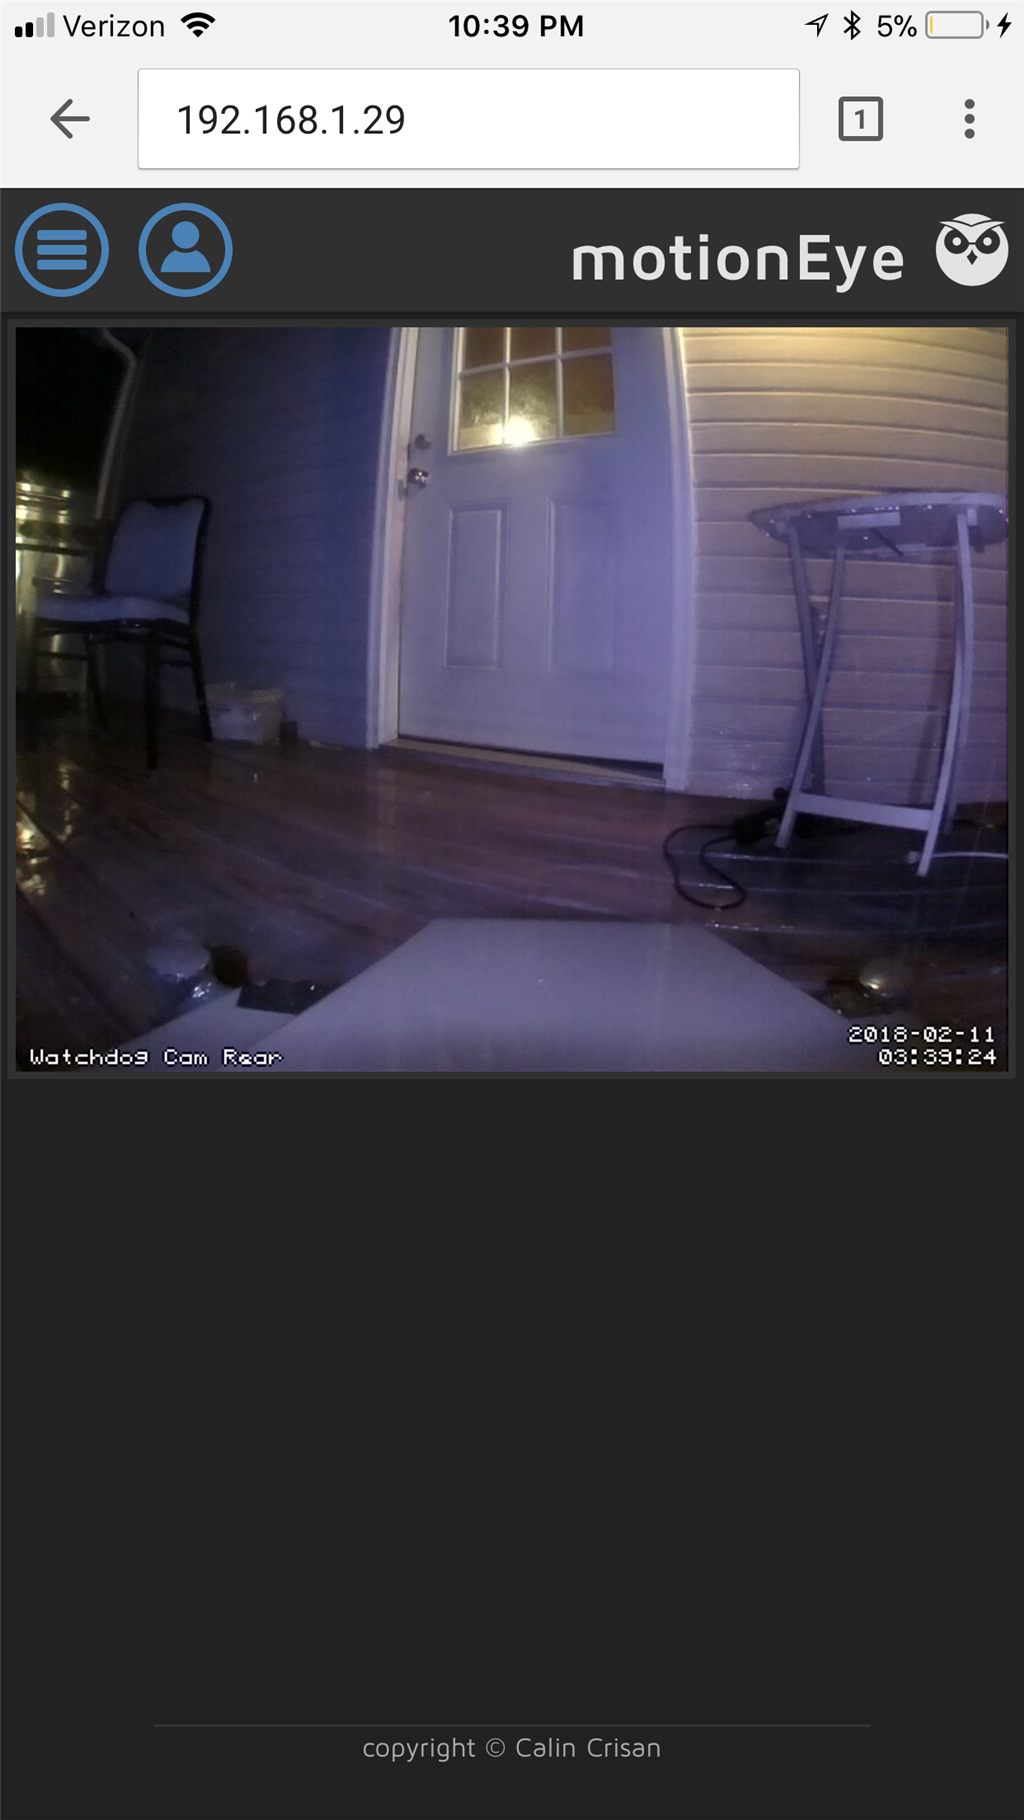
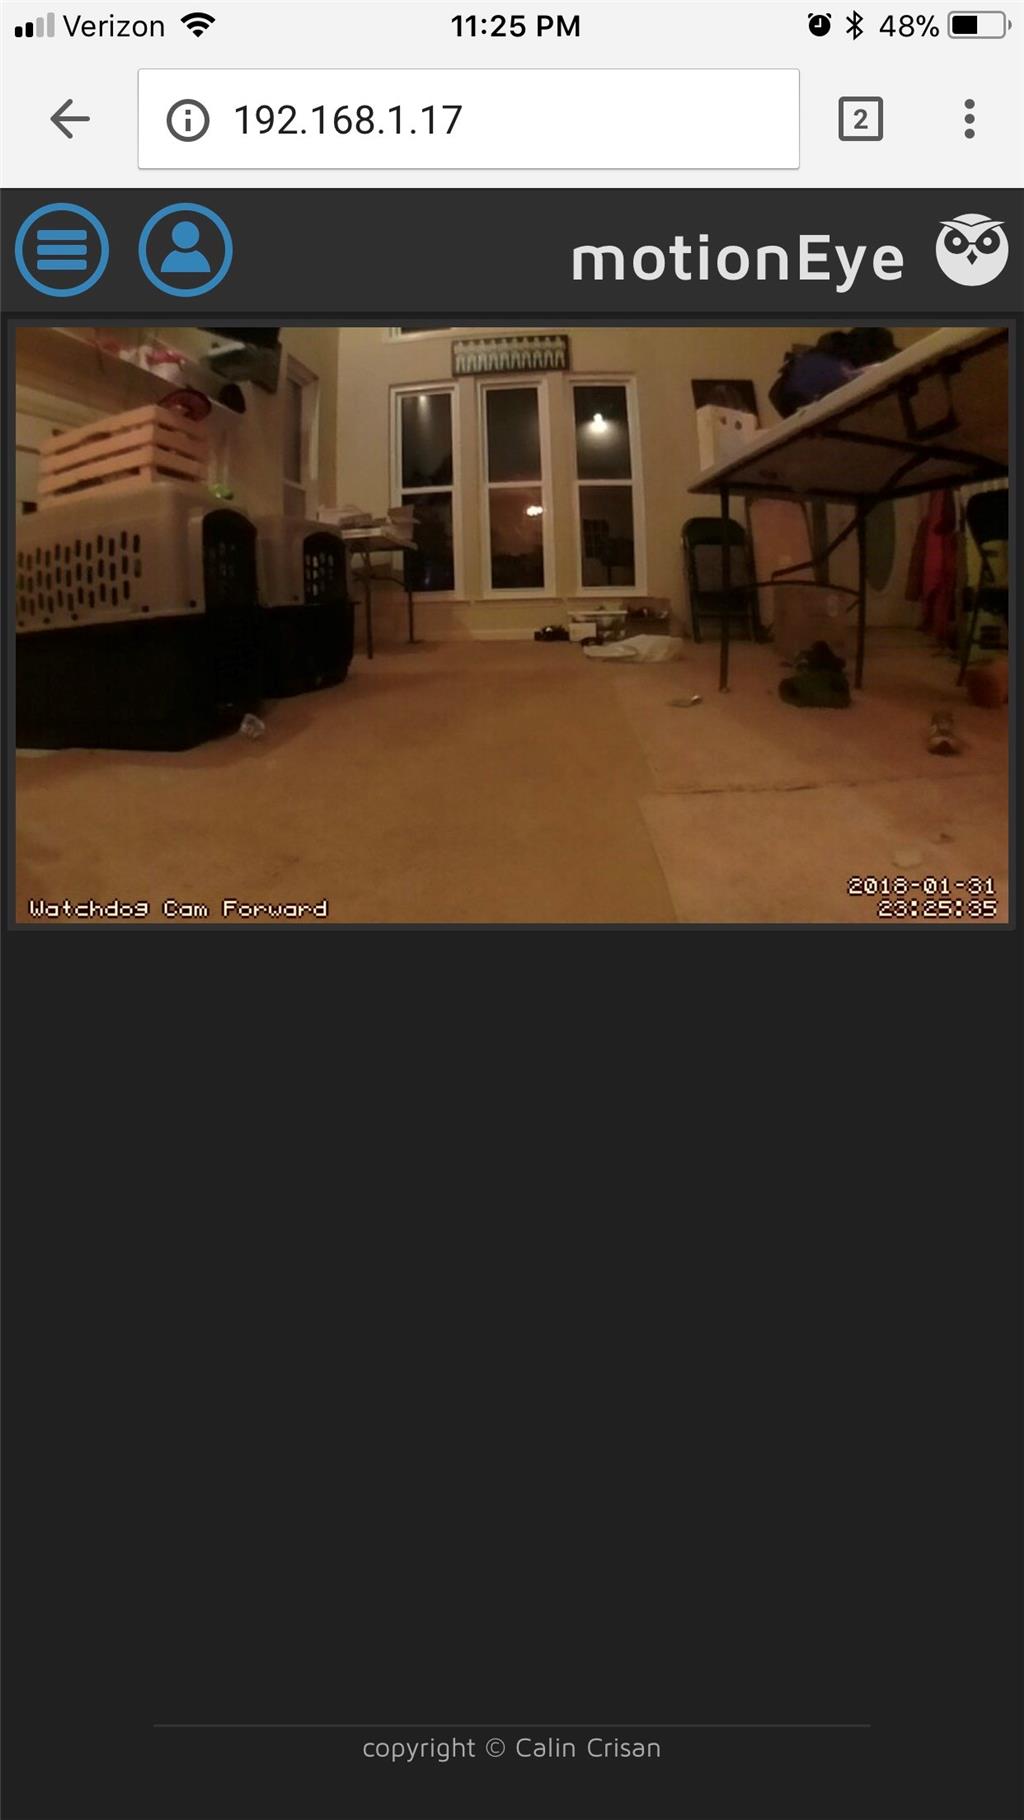
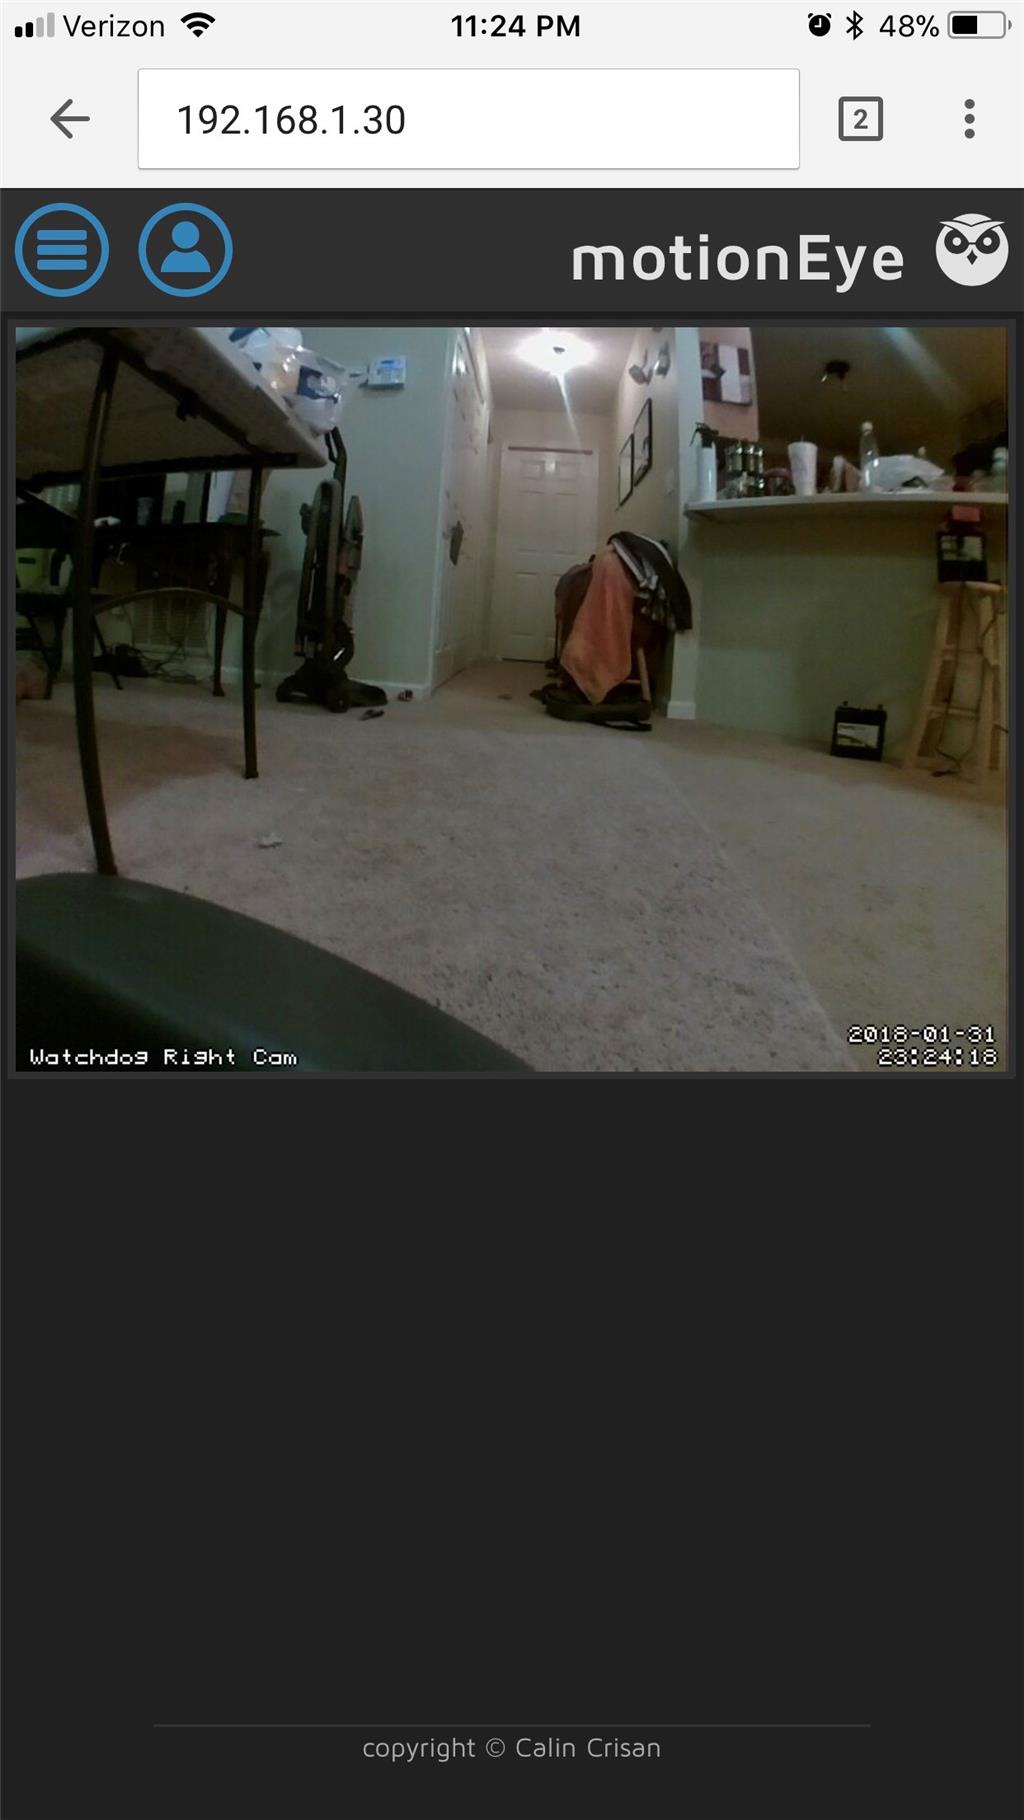
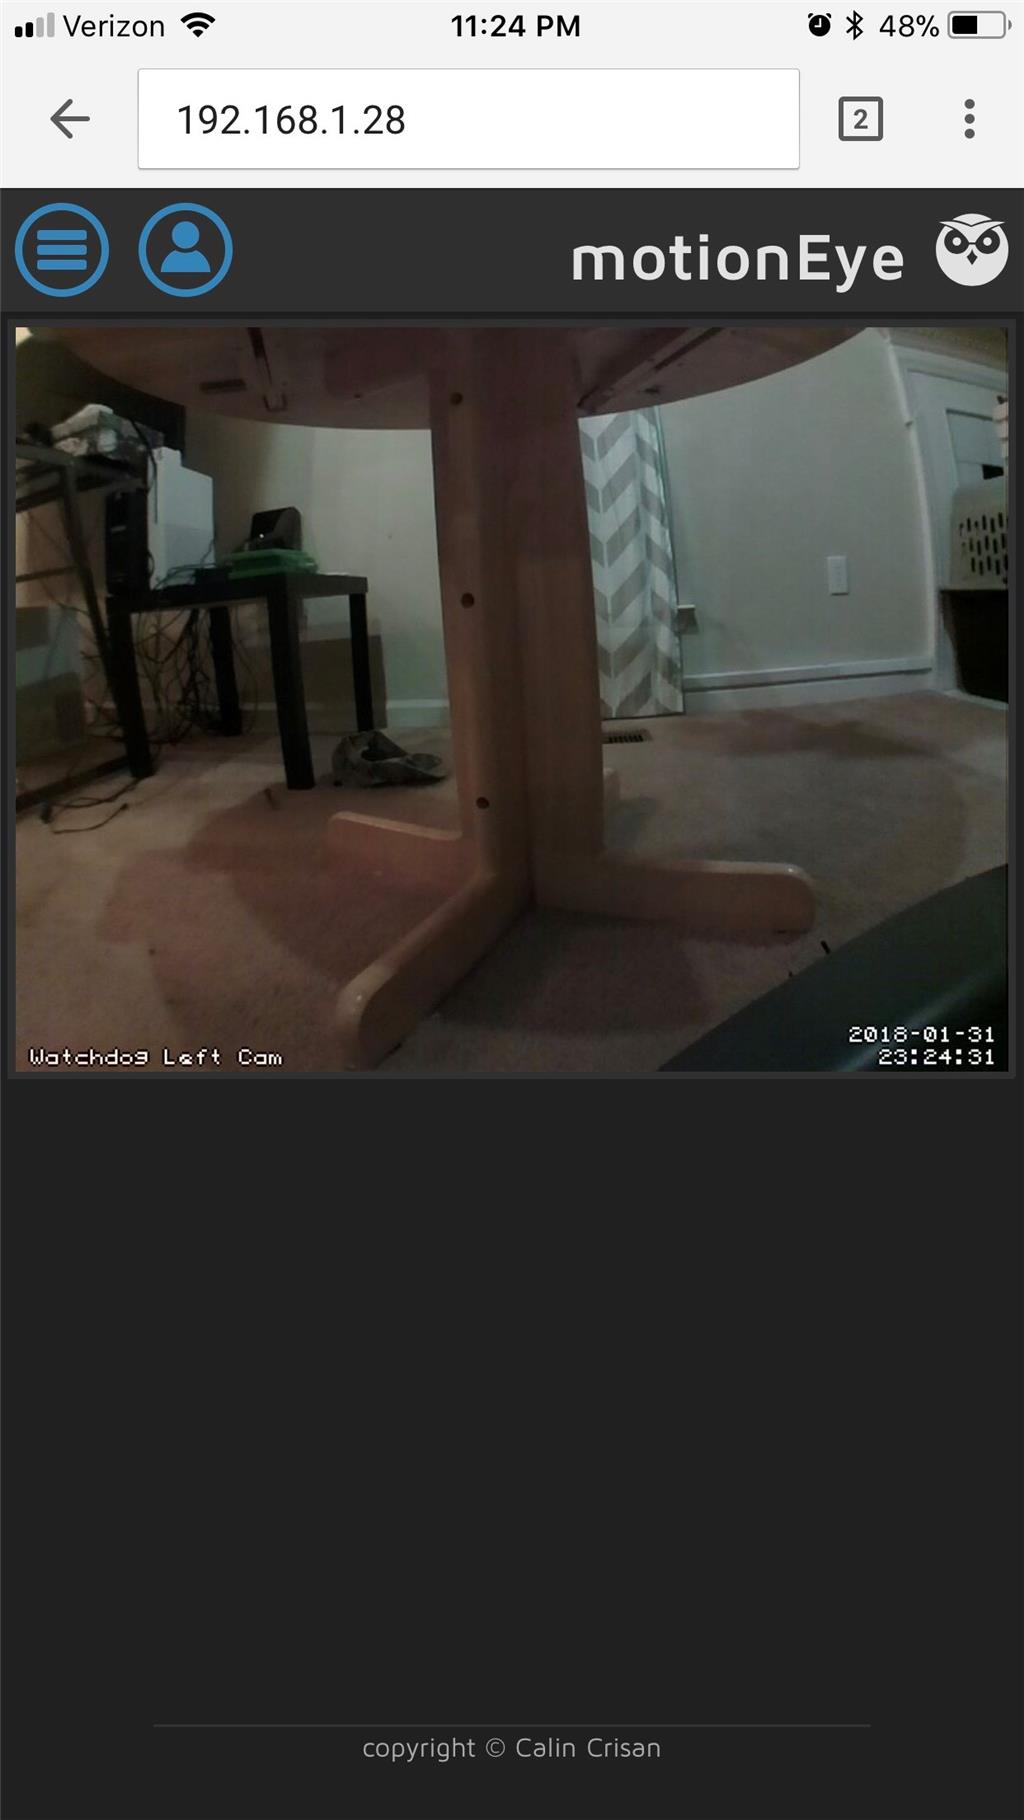
sample screen shots of night cam, pardon the cluttered play room.
Watchdog forward cam on initial boot
Watchdog right cam
Watchdog left
I forgot the Ip to the rear cam so I didn't grab a screen on that one.
This is amazing work. I missed following your work this past year or so while you were on robot sabbatical.
Thanks Dave I appreciate that! I enjoy your company and spectator-ship.
Nice work! I have used the same wheel chair base for robots before. Great platform to work with.
You do amazing work.
-Sean