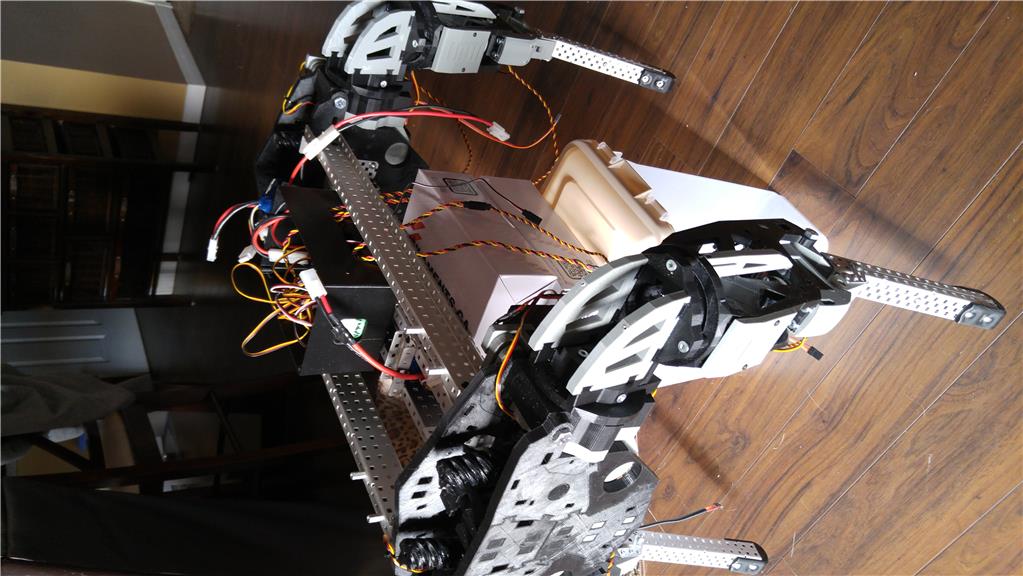
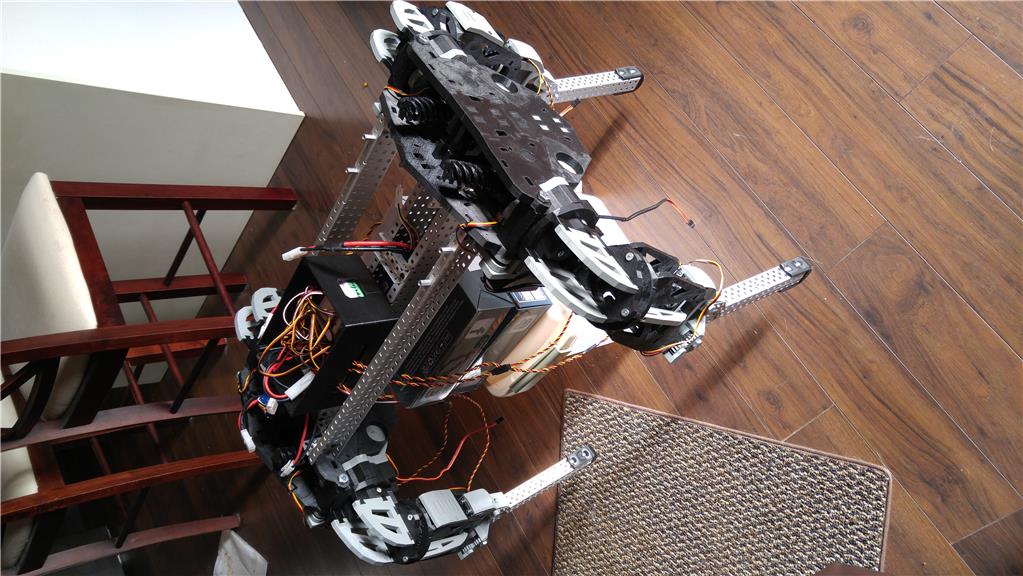
Pretty much a failed experiment for many reasons, but I already have ideas on a new version....
By Dunning-Kruger
— Last update
Discover more robots
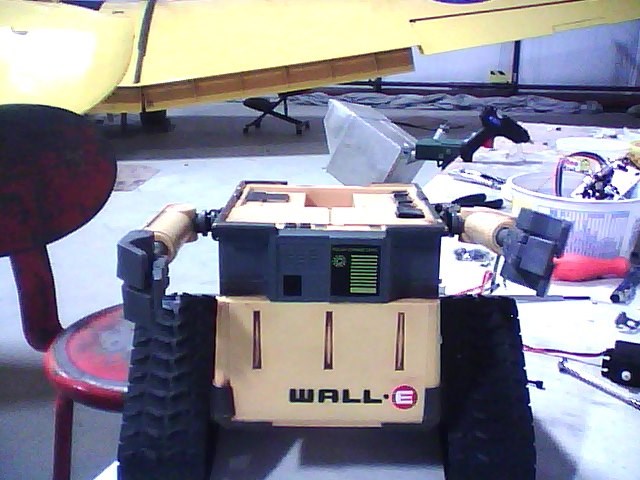
Cardboardhacker's Technopro's Wall-E Continued
Build Wall-E: arms and tracks assembled, head servo ready; camera hack, LED mod and head-tilt mounting ideas for EZ-B...
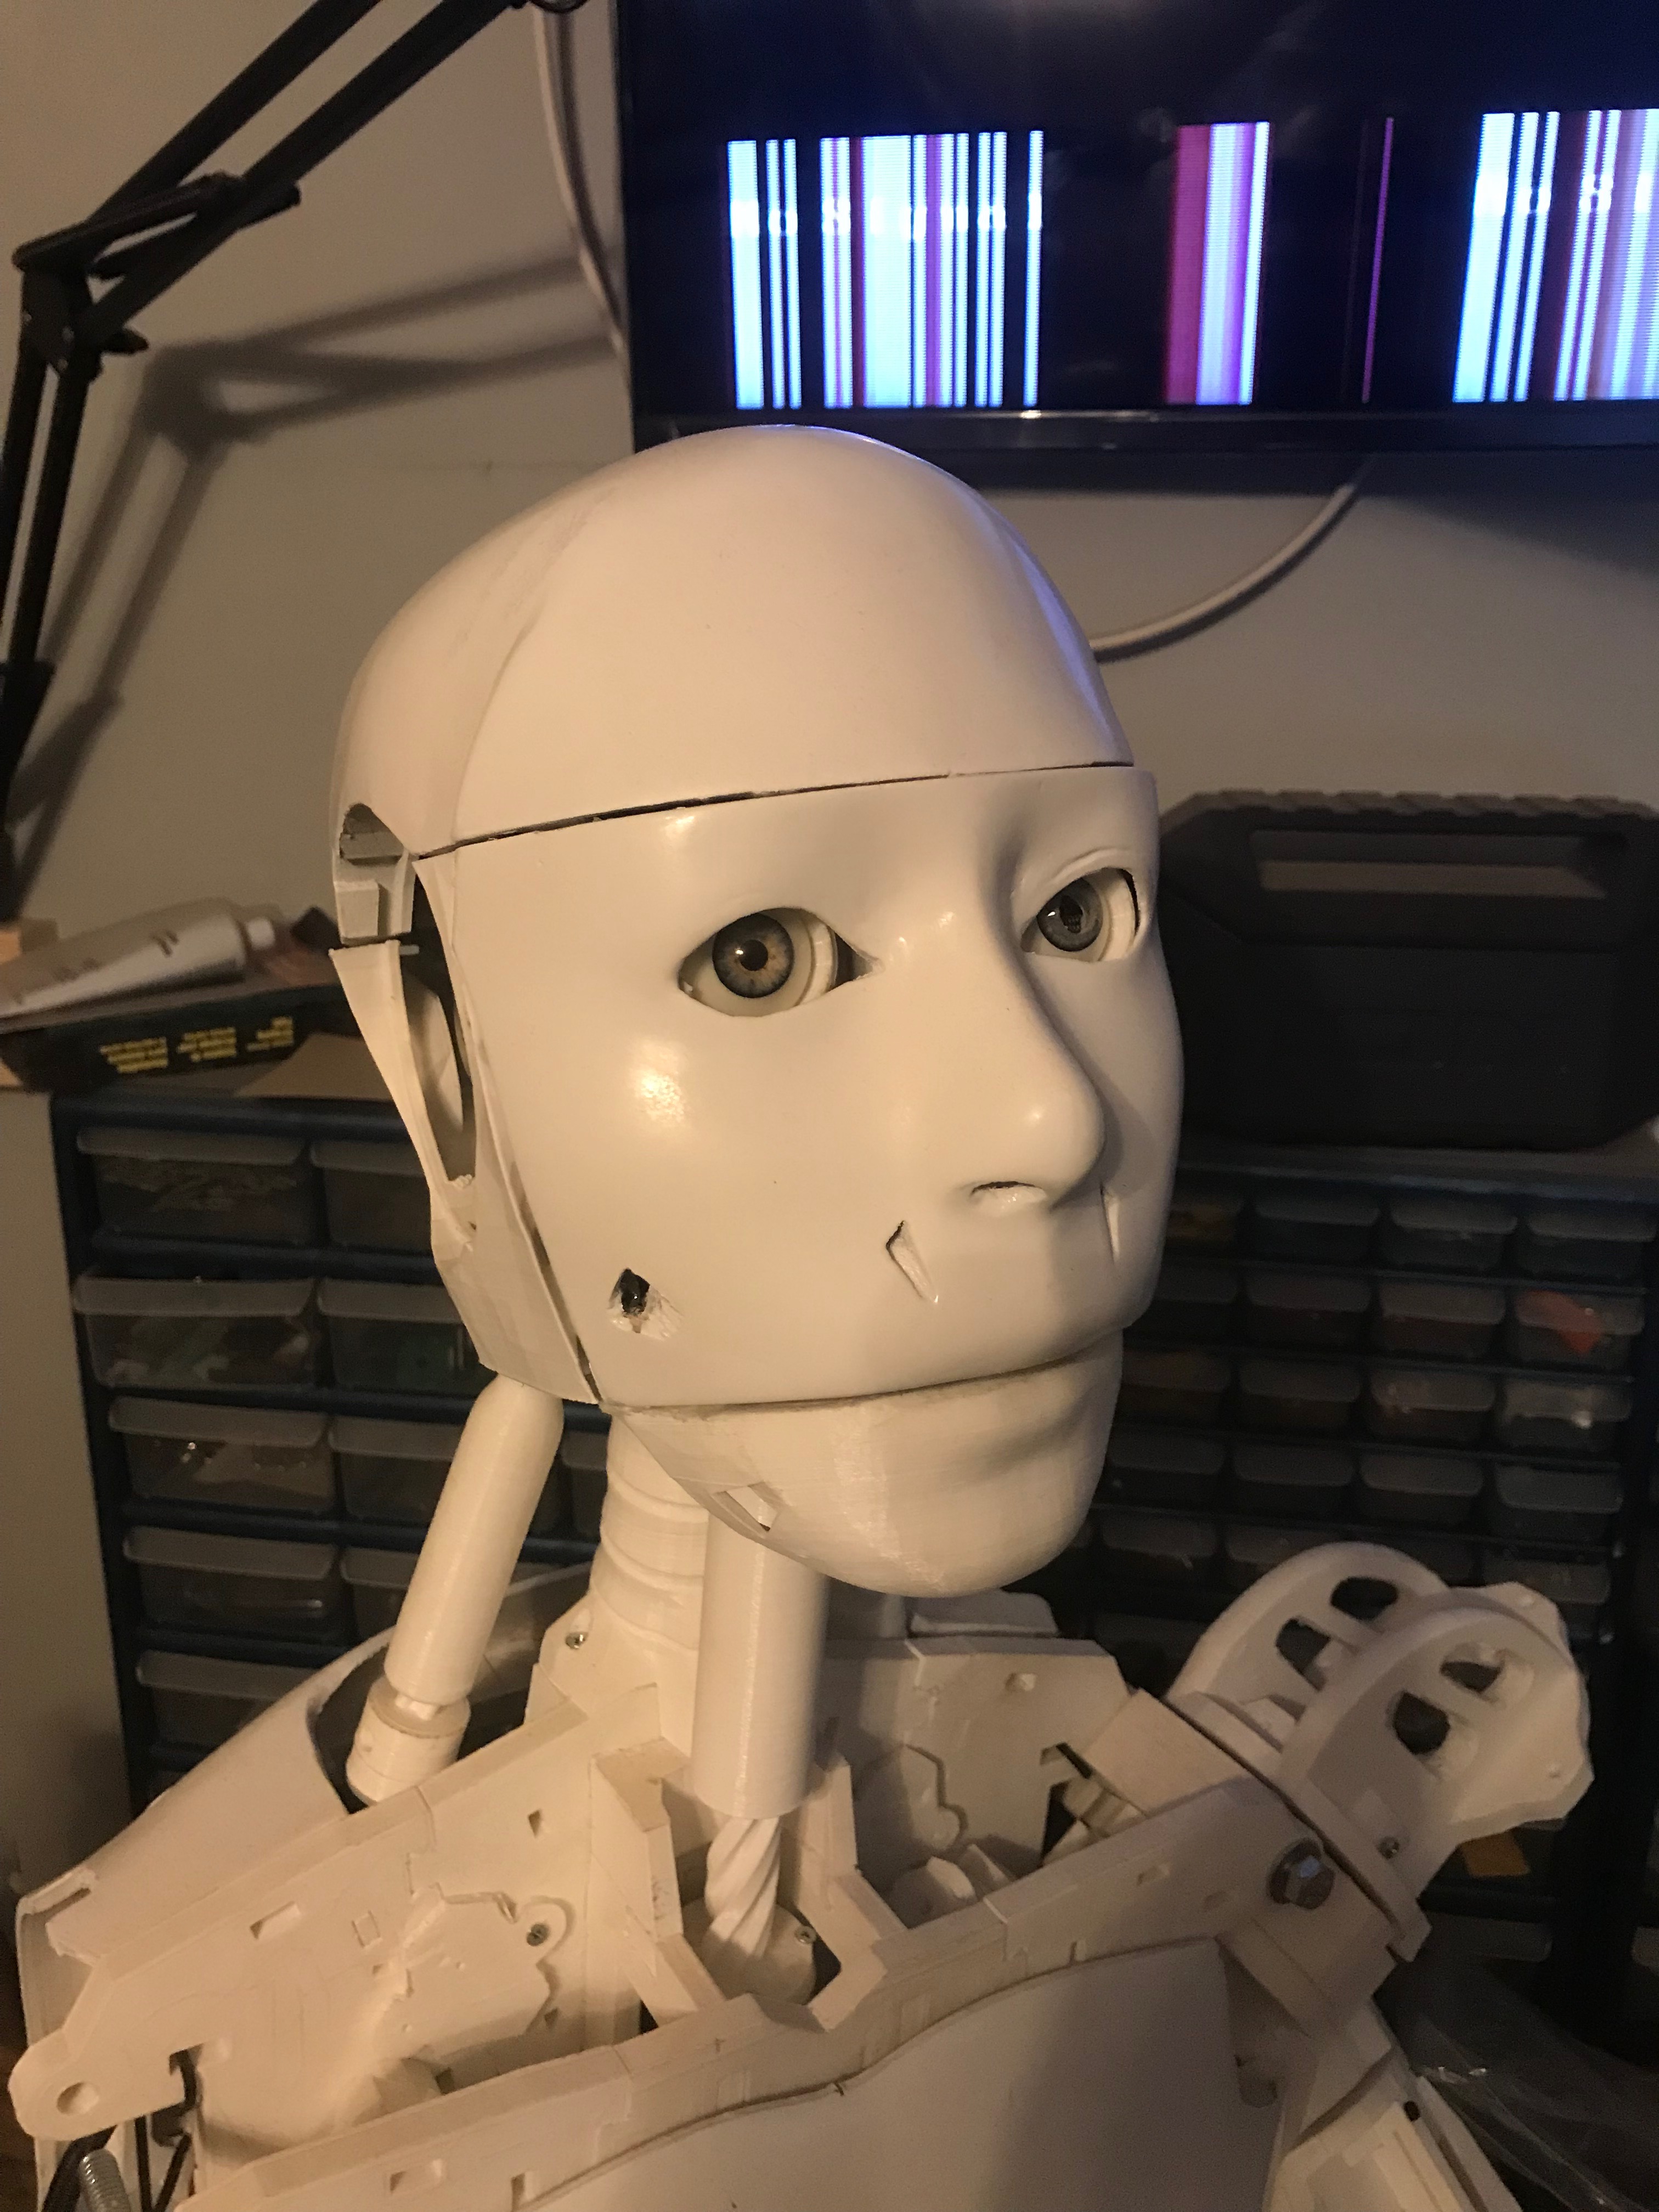
Intellamicrorobotics's Meet @Arti_Robot
aRTi robot built from about 20 lbs of PLA - a work-in-progress learning project exploring AI and robotics.
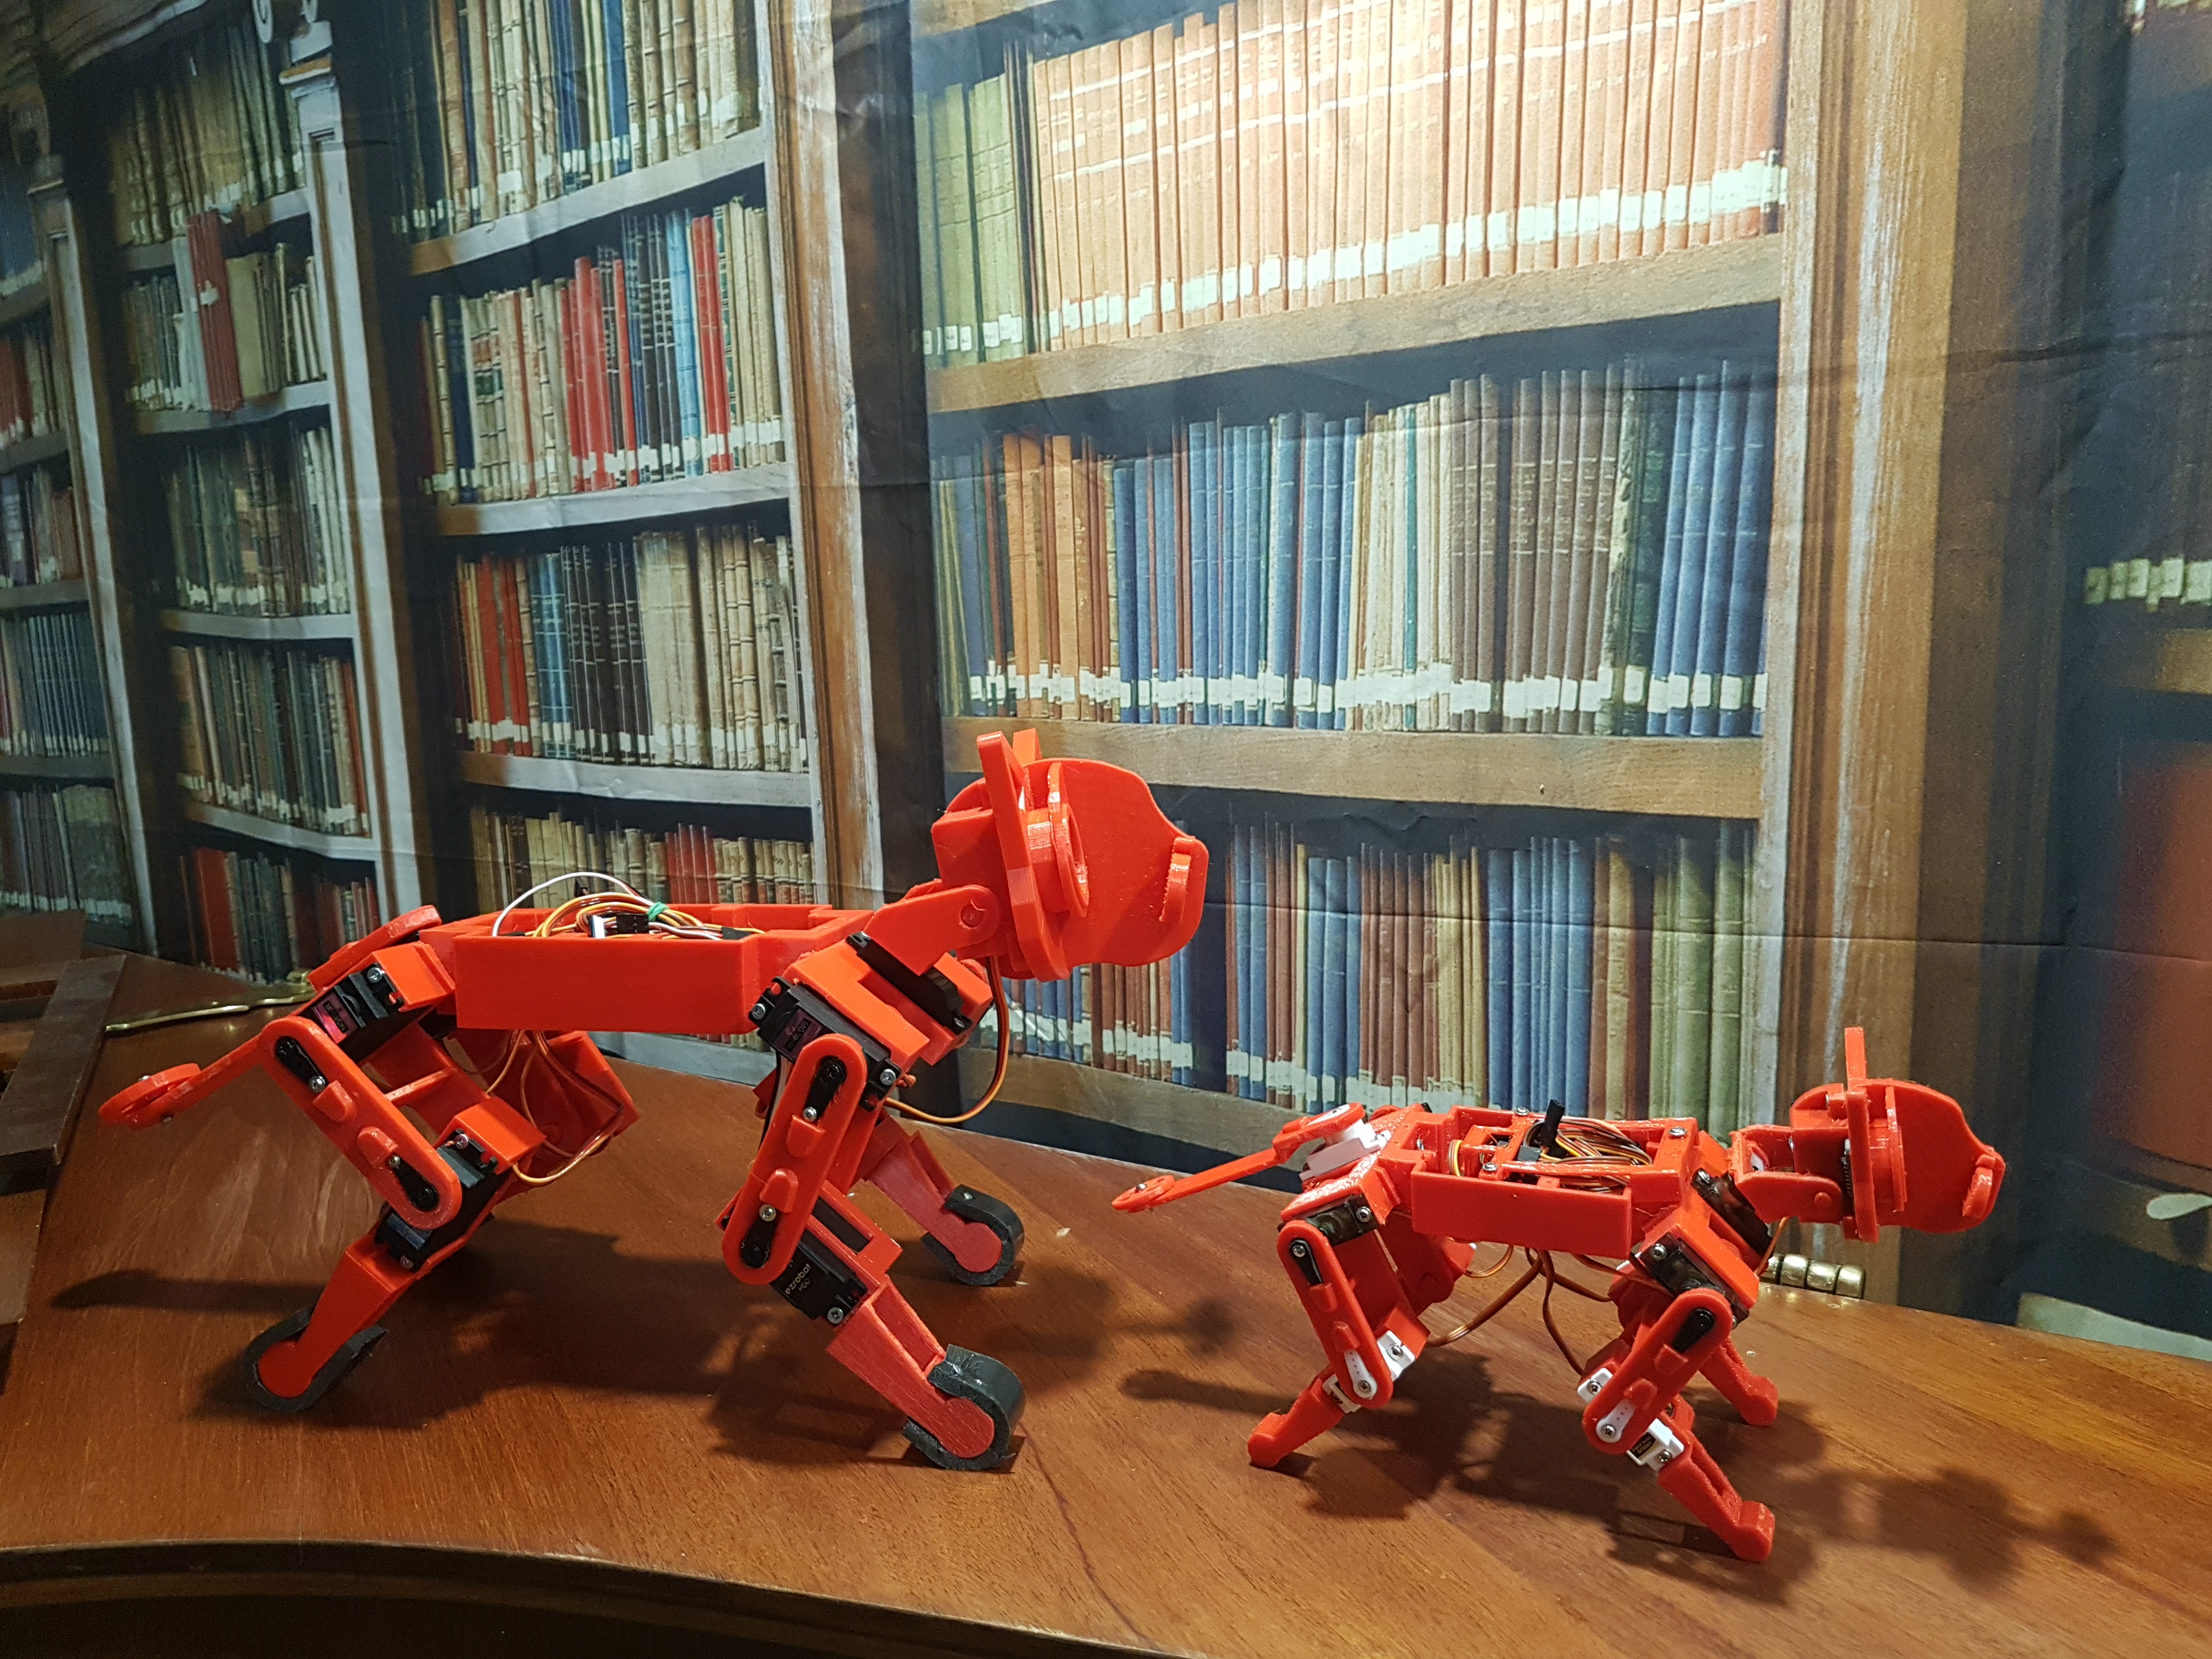
Nallycat's Big Nallycat A Large Version Of Open Cat
3D-printed Big NallyCat (OpenCat variant) using PET-g for durable, low-infill parts; planning full-size servos for...

That's a success! No where do i see failure Love it!
@RichardR. Great work and I like the idea of using some of InMoov’s design.
Definitely NOT a failure, and looks like you have put many hrs into this.
VERY impressive and can’t wait to see version 2.
Great job Richard. Looks like a job for some Dynamixel servos ,but quite expensive. Keep up the work never give up.
It is a better Quad than I have built! no failure, just your first version of a 4 legged Zoid beast!
I like it! I've been thinking of some like this as well since James Burton started working on his Open Dog. I modified the Clavi joint awhile back for another project so it could move in and out. I'll look for the files if you are interested. Maybe gears with less teeth could be used in the shoulder joint to speed up the movement of this joint. You'd lose a little torque but not that much. Perhaps a joint in it's back could be added to turn it left and right - that's more how an animal turns. Maybe InMoov's stomach joint could be used. Also, have you seen Aerius's elbow joint? www.thingiverse.com/thing:2778760. I built it and it's very strong with a smaller servo.
Anyway, looking forward to seeing what you come up with.
I like the quad concept. I had just been thinking about playing with building a small quad using EZ-Bits when you posted this.
Alan
@RichardR: Thanks for sharing. Me like !
@jstarne1: Nice hack thanks for sharing.
@bhouston: Thanks for mentioning the OpenDog project: https://www.xrobots.co.uk/open-dog-the-open-source-robot/ btw James is using the odrive robotics controller to drive the brush-less motors.
I also think your Robot is not a failure, it is very good, and I also think I does need a waste joint. I was looking at Bob Houston's idea about using Aerius planetary elbow for inmoov. this looks very strong. I am thinking of printing this for my Inmoov. A question for @Bob Houston who already built the Aerius inmoov elbow, How is the micro switch wired, is it a permanently open micro switch and just cuts the power to the servo when activated, or does it work some other way?