Hi, I'm working to customize JD with much longer arms. Is there a way NOT to have the arms fly out straight when you initially connect? Thanks

bmarkert1985
USA
Asked
— Edited
 Resolved by Nomad 6R!
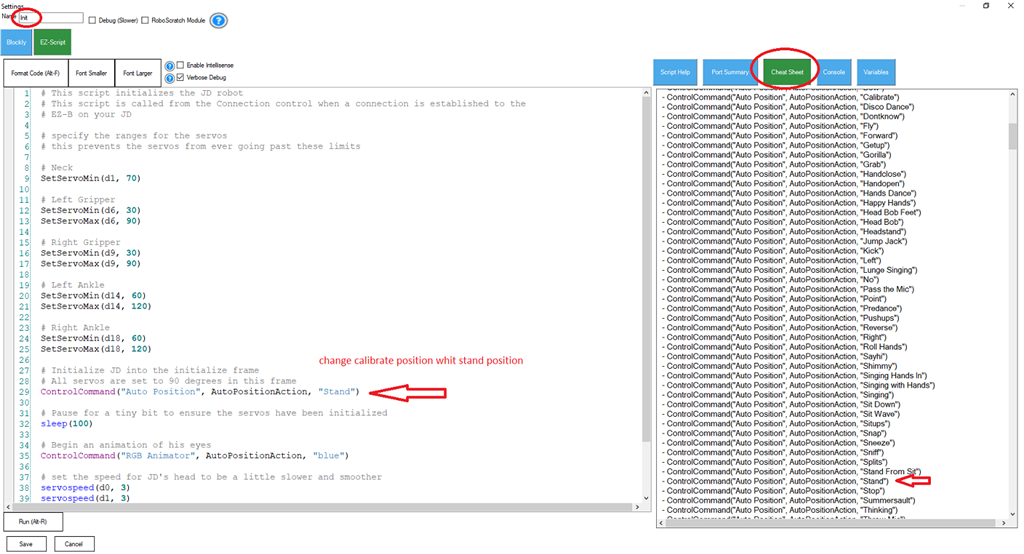

You can modify the init frame in the auto position. That’s the frame that initializes the servos
here a pic .delete calibrate position.and put in the stand position.
Thanks This was very helpful
bmarkert1985
a picture is always the best thing.