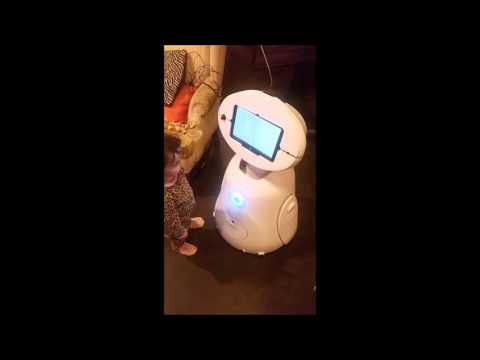
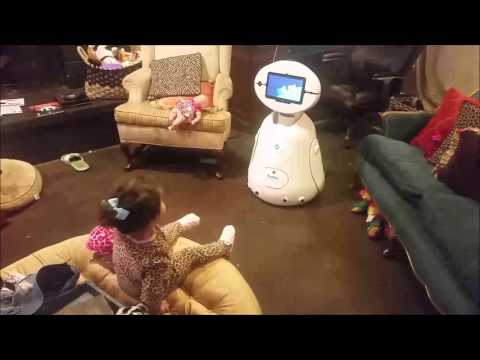
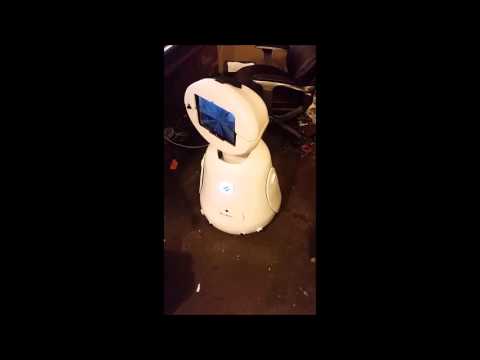

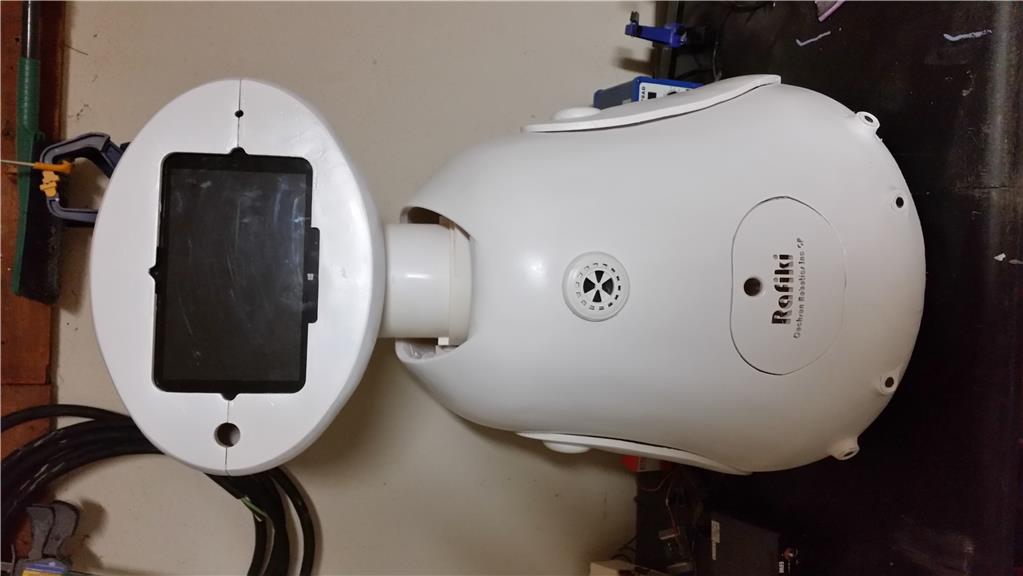
For those of you who are registered at CochranRobotics.com, I have opened up a Rafiki build Status page. This shows photos of the build process of the prototype. The goal is to be able to start programming of the robot functions in about a week. Enjoy and let me know your thoughts.
https://cochranrobotics.com/RafikiStatus
BTW, this is where I have been since the summer. A lot of working on this project and not so much time to talk in the community. I sure miss having time to hang out here.
By CochranRobotics
— Last update




Discover more robots
Rb550f's Okio J5 Style Robot Project
OKIO J5-style 44" robot built from an upright vacuum: Dremel head, LED eyes, HD USB camera, Windows 10 tablet,...
Artbyrobot's Advanced Realistic Humanoid Robot Named Adam
Build an advanced humanoid replica that walks, talks, mimics expressions, performs chores, art, and sports with lifelike...
Markthebotbldr's Drone Tracking Fun
DJI P4 active tracking follows a hacked Friendly Robotics Lawnbot using Sabertooth motor controller, switchable EZ-BV3...

First test of subsystems working together in the robot. There are a lot of tweaks that still need to be done but, it moves
David,
Wow ! Are all parts 3d printed ? The design reminds me a lot of Buddy robot, probably is a winning formula no ?
Nice Bot !
Everything was 3d printed.i think it is about 120 parts all stuck together and then bondo, sand and paint.
I have been wanting to remove the ball caster in the back and go with an Omni directional wheel. The ball caster is too loud. The neck motion up and down will probably be switched out to use a linear actuator instead of the servo I'm using. The head is too heavy for the servo. Other than that, I am happy with how it all is working for the most part. I will make changes to the wheel controller subsystem to ramp down when stopping. It stops abruptly right now.
Most of my time has been spent on the build and subsystems. I'm happy with how well everything works together and how simple this design is to program.
David,
I saw the video, it seems the head is shaking a little, probably needs more support.
Does perform well over carpet floors and threshold ? I notice some robots tend to get stuck...
I don't see space for big sensors i read you have plans for slam ?
PS: btw we exchanged a few emails before regarding 3d printers.
SLAM Lidar is in the neck. Carpet and threshold are not an issue once the ball caster is removed.
Neck is shaky right now. This is a reason that stopping needs to be ramped and the servo needs to be replaced with a linear actuator.
David, very nice robot, it looks really good. A linear actuator will be expensive, I had the same head bobbing problem and solved it with a spring damper on the rear of the head, this could save on your production costs.
Tony
Awesome David....
Thanks Tony. I will look into it.
Thanks Richard.