




 Download EZB File
In order to use this app, you need Synthiam ARC software.
| For | ARC |
| Author | TMesserschmidt |
| Created | |
| Last updated |
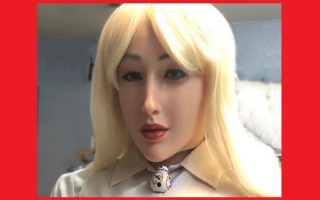
Simone: Life-size humanoid "fembot." Part of #OpenFembot. Fully Articultated head. Each arm has two degrees of freedom. Build instructions on servo Magazine. Inspired by Hanson's Sophia robot.
