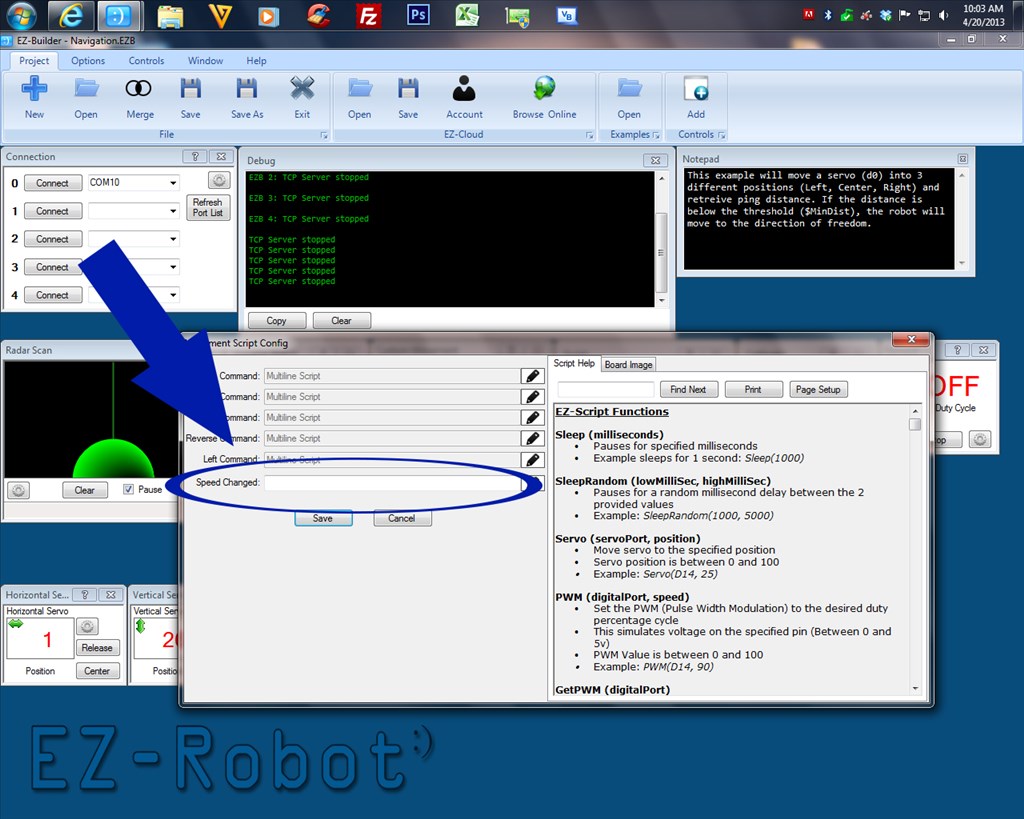
I can't find any info on what this does and how to use it. any examples out there?
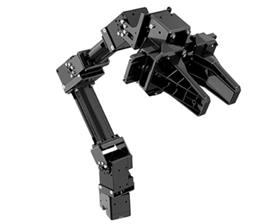 Robotis Openmanipulatorx
— Inverse kinematics for Robotis OpenManipulatorX: compute joint angles and MoveTo 3D (cm) positions, supports camera-to-CM mapping for pick-and-place.
Try it →
I can't find any info on what this does and how to use it. any examples out there?
