
Hi,
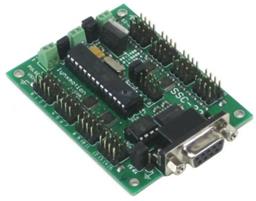
I've been playing around with this sensor and I haven't had any luck getting it to work with ARC. The Script I am using is this: I2CStart() I2CRestart() I2CWrite(0x3C) //write mag I2CWrite(0x30) //Select register OUT_X_L_M I2CStart() I2CReStart() I2CWrite(0x3D) //read mag I2CRead(Auto,8)
Even though I get a reading, it never changes I get the same thing until I remove power from it: I2C Response: 16 32 3 1 211 254 223 0
Some of the data sheets I have been reading: https://www.pololu.com/file/0J433/LSM303DLH.pdf https://www.pololu.com/file/0J434/LSM303DLH-compass-app-note.pdf
So far I am batting zero, has anyone else worked with this module before?
I'd appreciate any help with this

I2C changed a few months ago, I've yet to use I2CRead, I will have a look for the topic in which it was discussed when I get chance.
In the mean time it may be worthwhile to try changing the I2CRead commands to something like $gps=I2CRead(Auto,6) or maybe even $gps=I2CWrite(Auto,6). As far as I know, just using an I2CRead on it's own would be much like using a GetADC or GetPWM without storing it in a variable.