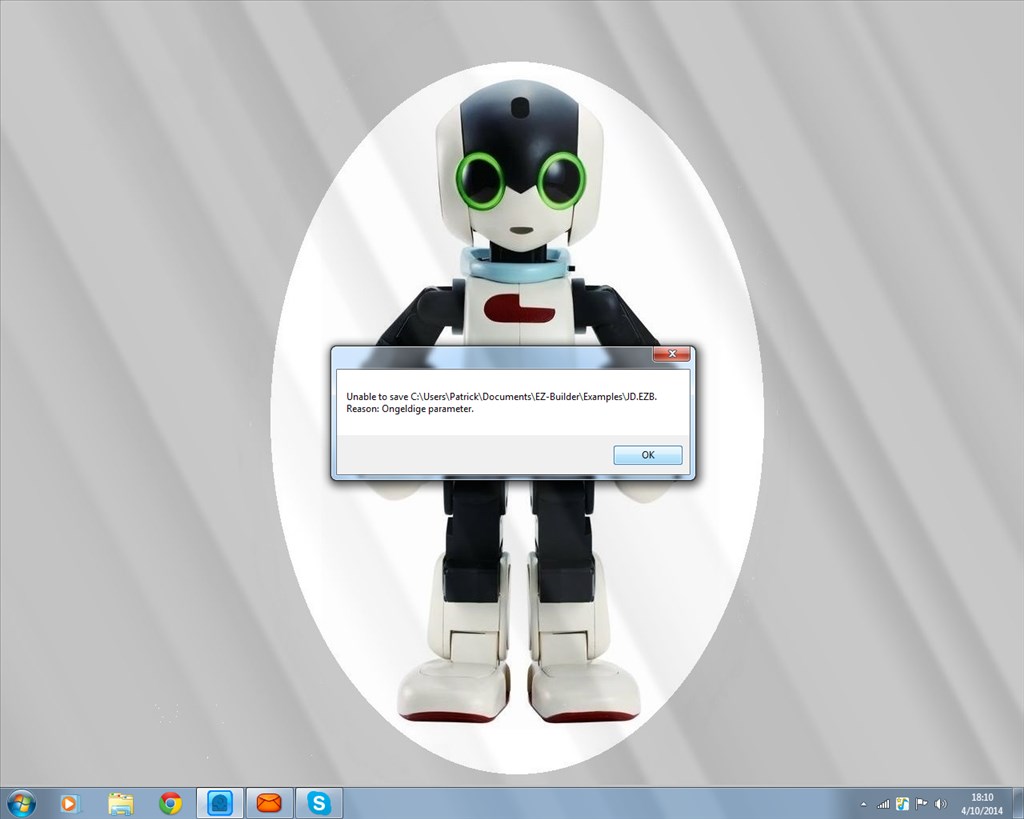
Community Robot Questions What Means This Error PRO Nomad 6R Belgium Asked Oct 2014 — Edited Oct 2014 What Means This Error ARC Skip to comments Jump to end i got this error when closing ARC. Quote Jump to end Upgrade to ARC Pro Synthiam ARC Pro is a new tool that will help unleash your creativity with programming robots in just seconds! Compare Pro Features View Subscription Plans Nomad 6R PRO Belgium #1 Oct 2014 found it.means its not made by me. Reply Quote Share Login to post a comment
PRO Nomad 6R Belgium Asked Oct 2014 — Edited Oct 2014 What Means This Error ARC Skip to comments Jump to end i got this error when closing ARC. Quote Jump to end


 Ultrasonic Collision Detection
— Stops robot movement (no steering) when an EZB-connected ultrasonic sensor detects an object within a set range; integrates with scripting and paused polling.
Try it →

found it.means its not made by me.