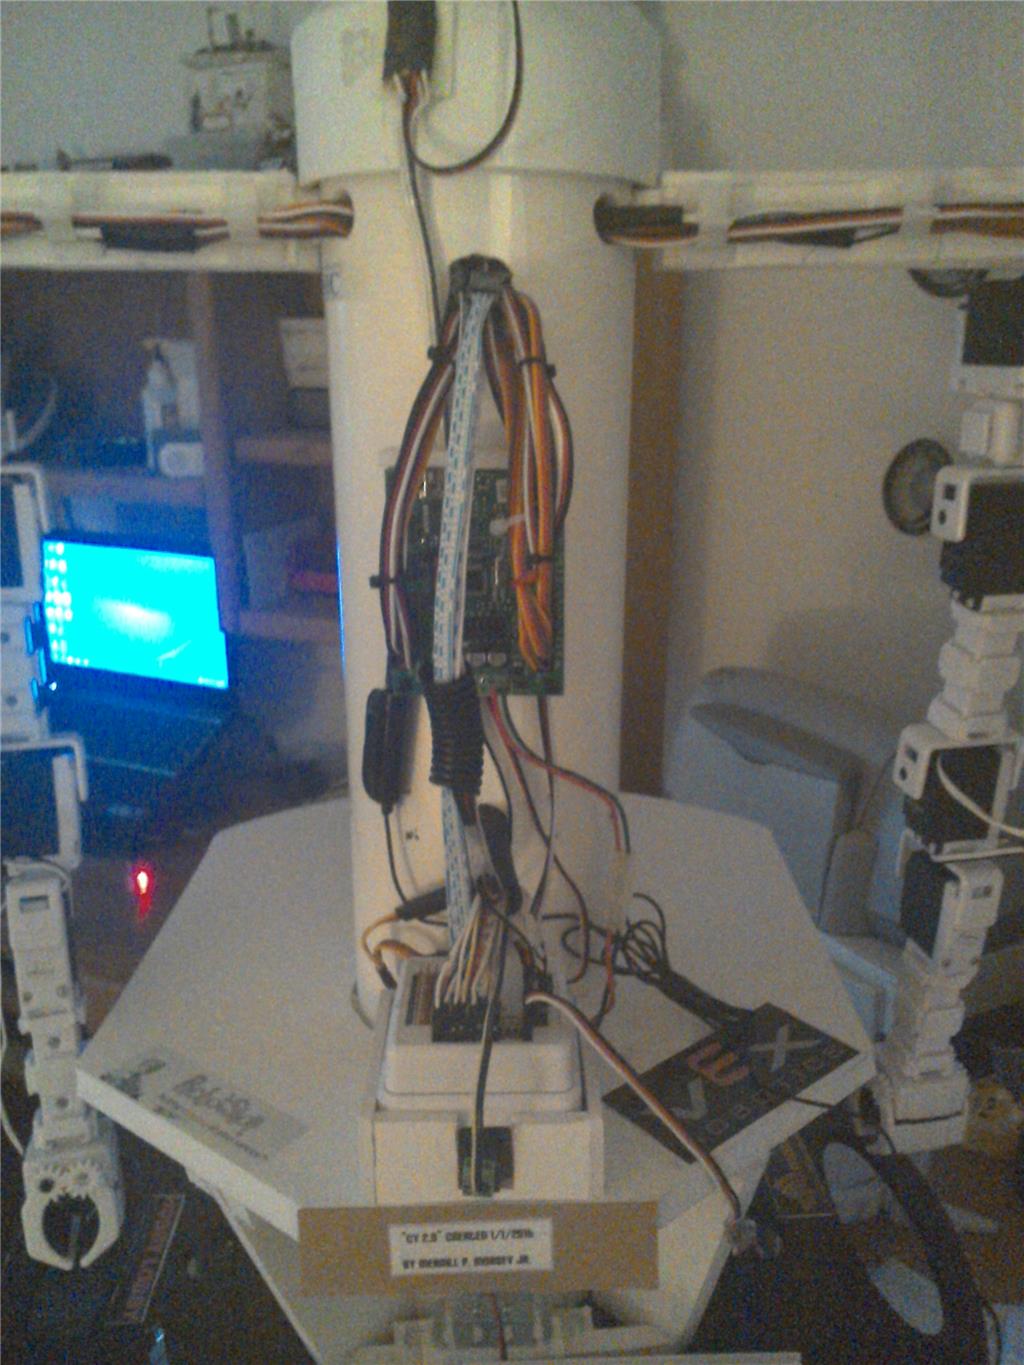
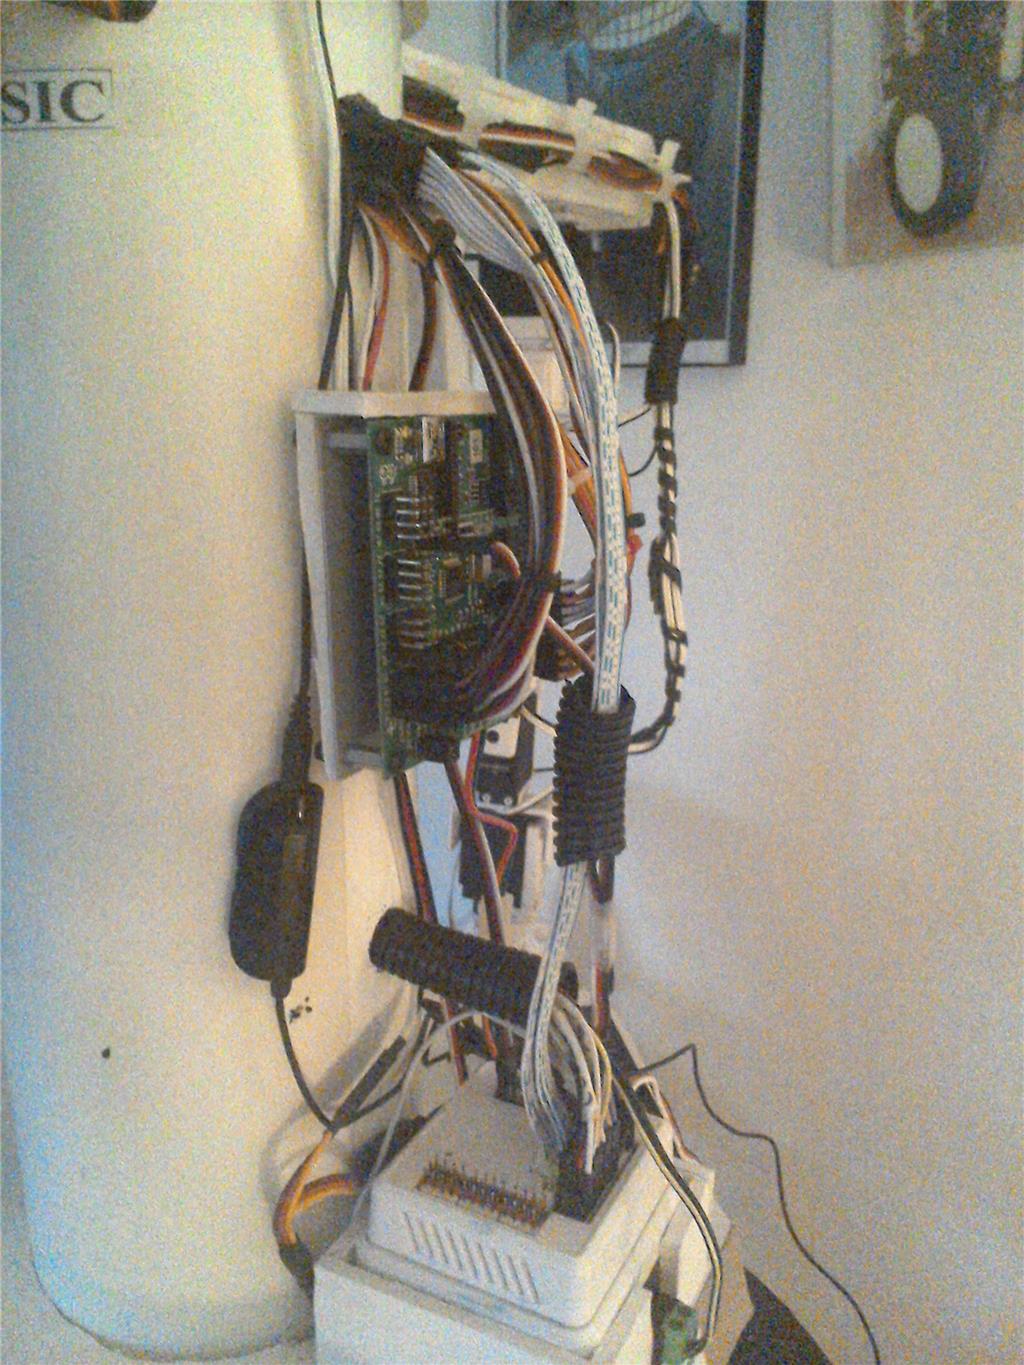
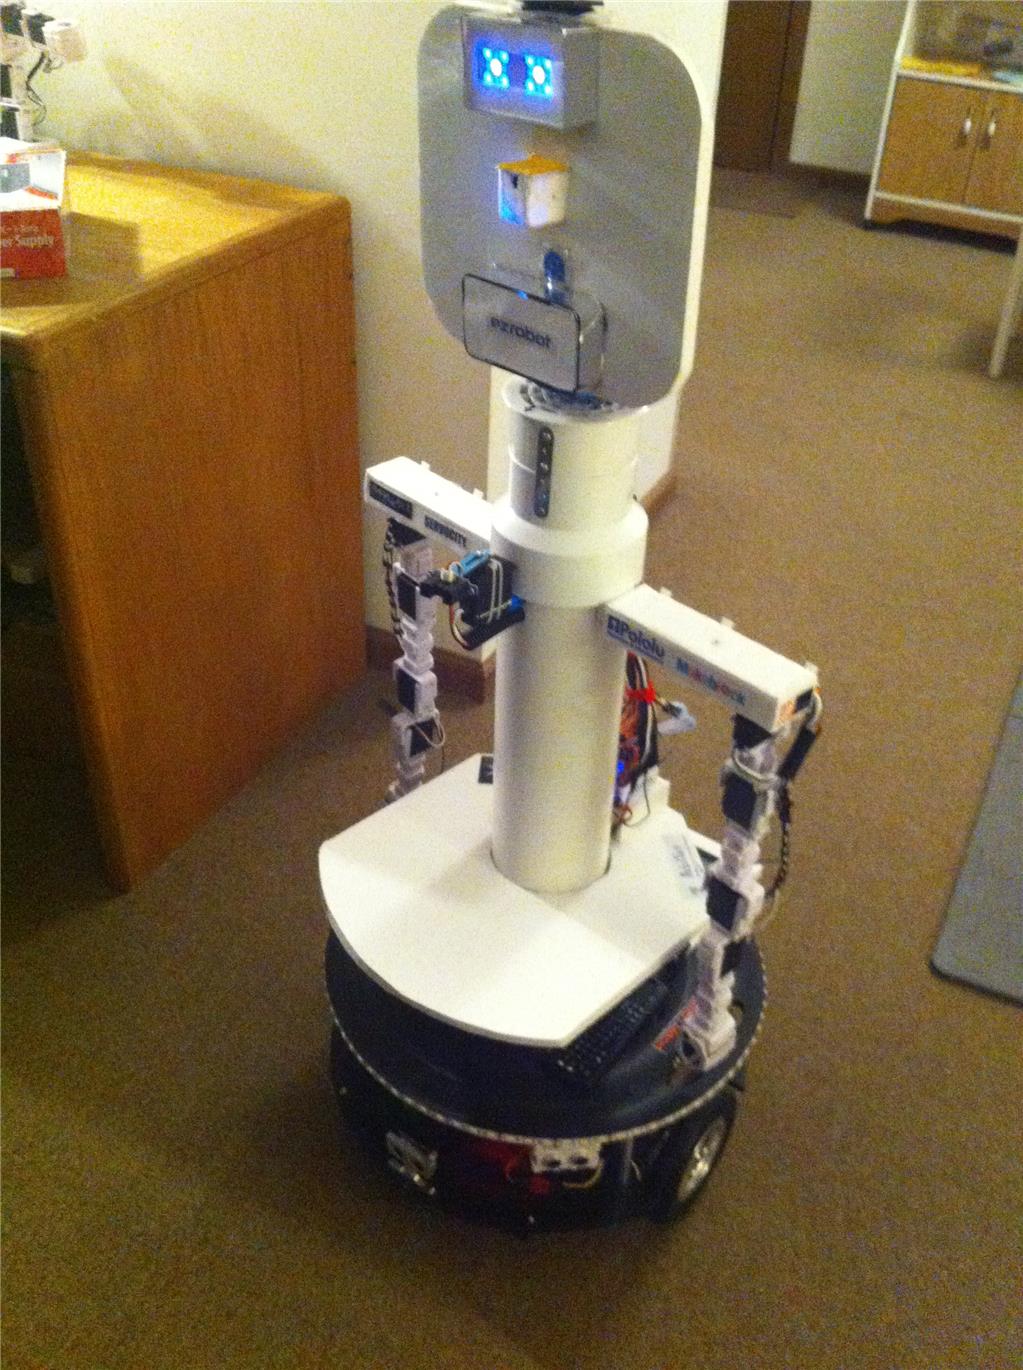
Hi guys, Thought I would show off my robot again. This is Cybot 2.0. The big change I did was get rid of that big laptop of a head and went with something a bit more normal size I think, now that I have an Acer W3 to control it. The head now is just basic speaker,ezb camera, and the rgb animator. Do plan on adding more cool sensors later on.
I hope to do a video of him moving about soon too.
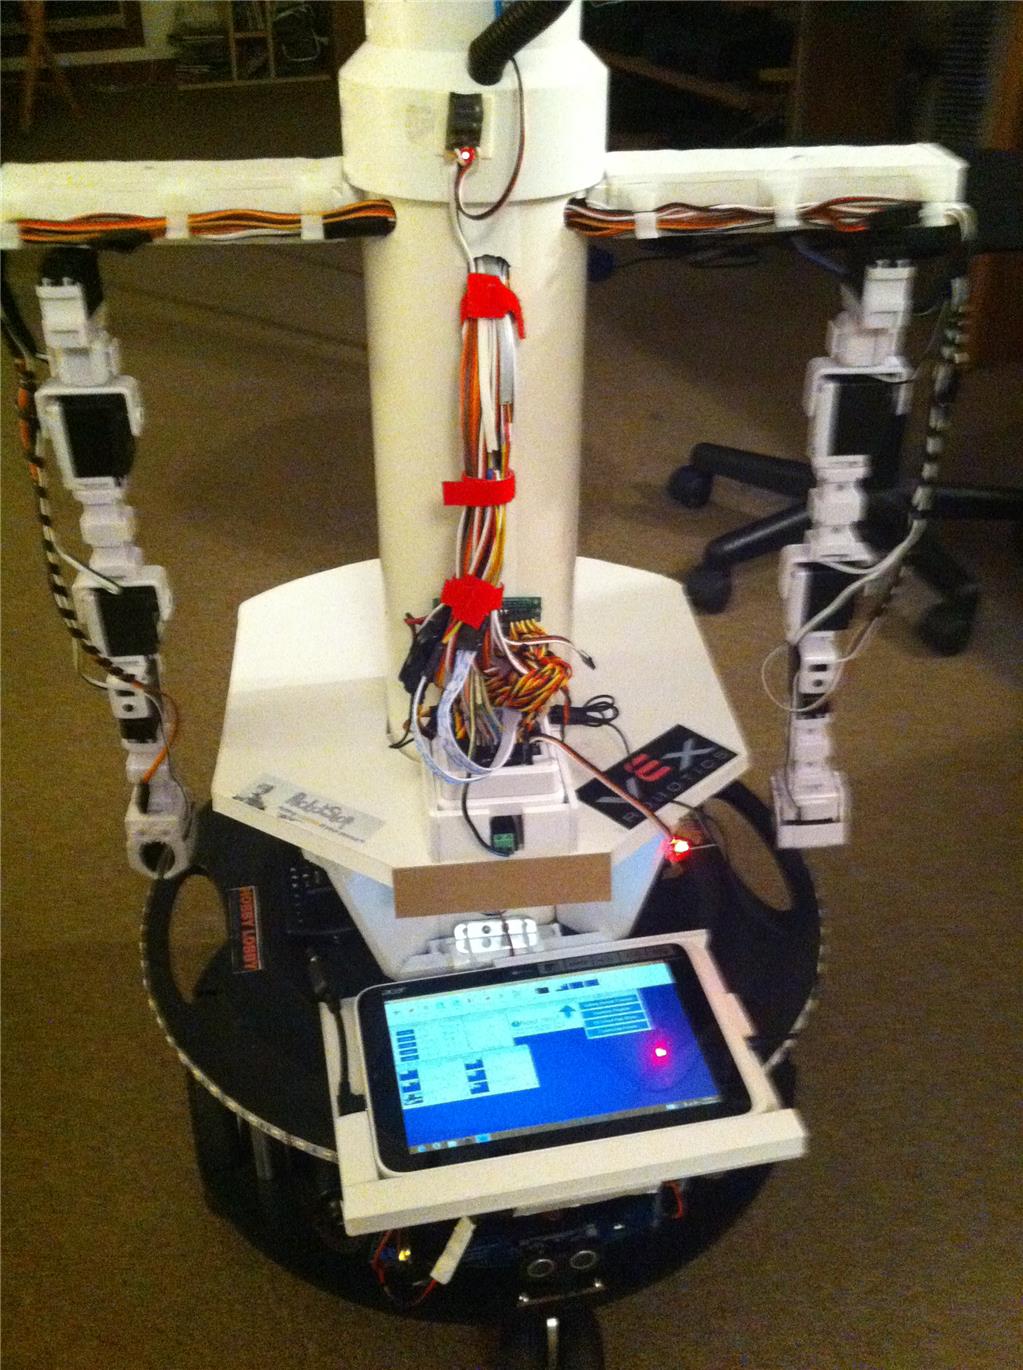
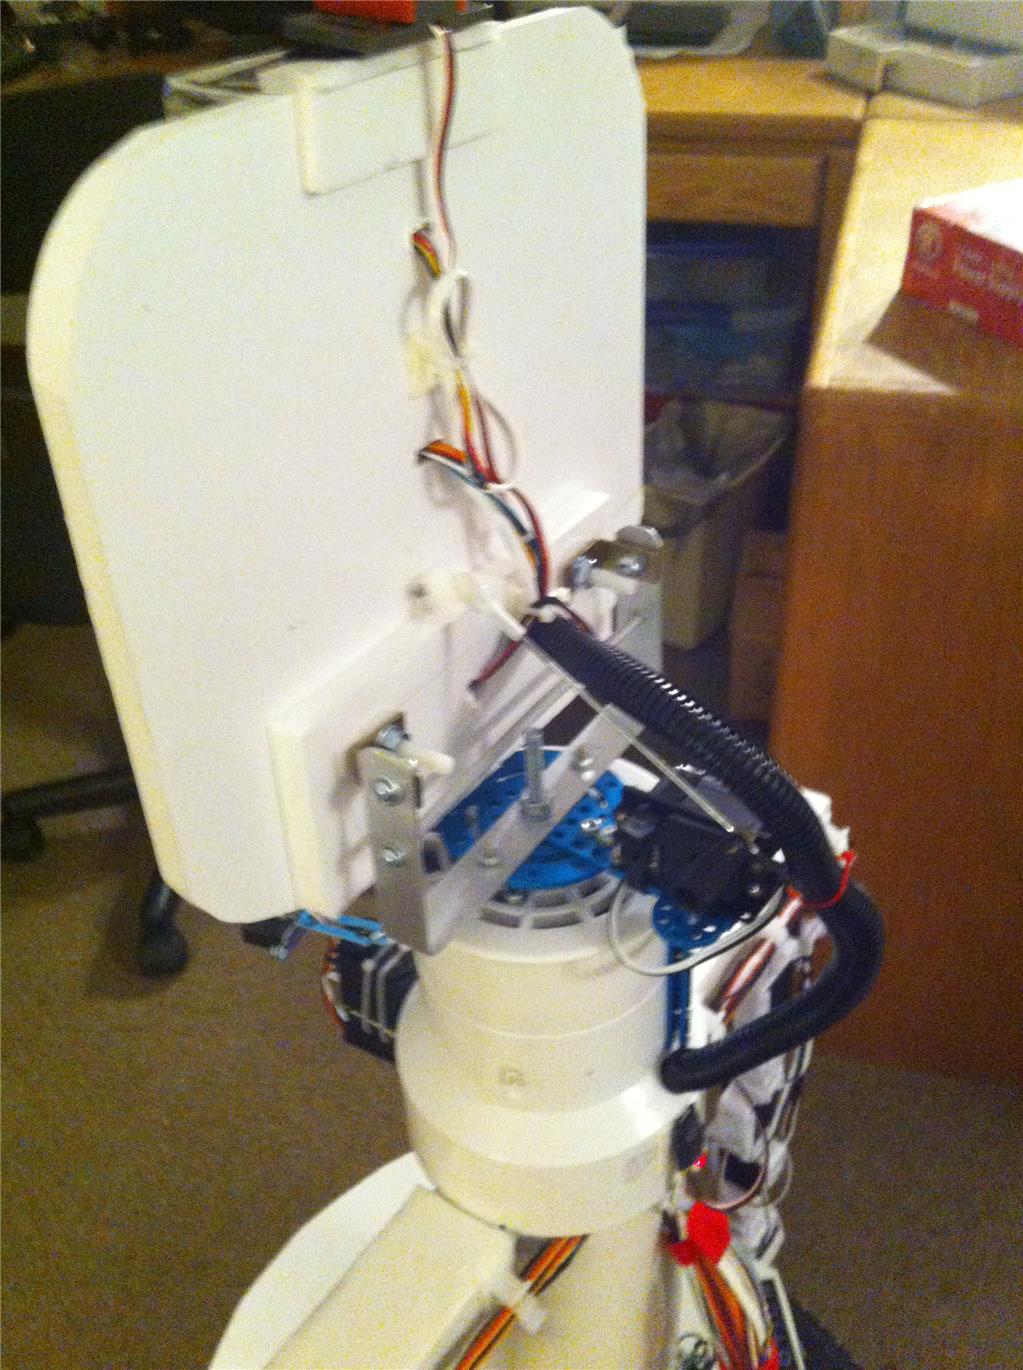
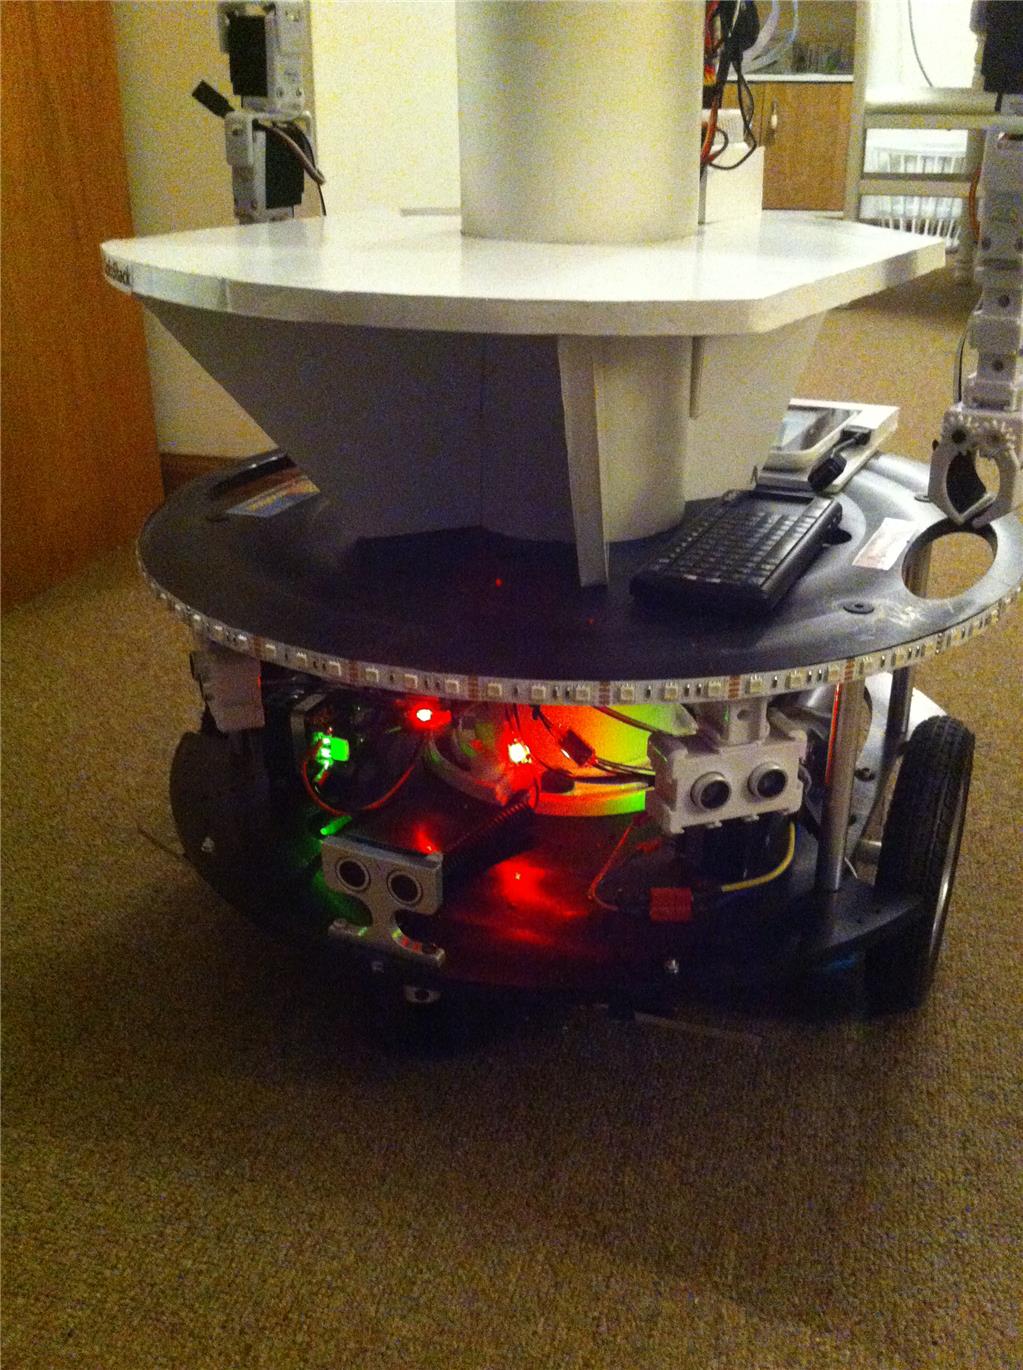
By RoboHappy
— Last update
Discover more robots
Ezang's Motion Detector
Control AM312 mini PIR motion sensor with ARC serial monitor and Arduino - DC2.7-12V, 3-5m range, 100 angle, low...
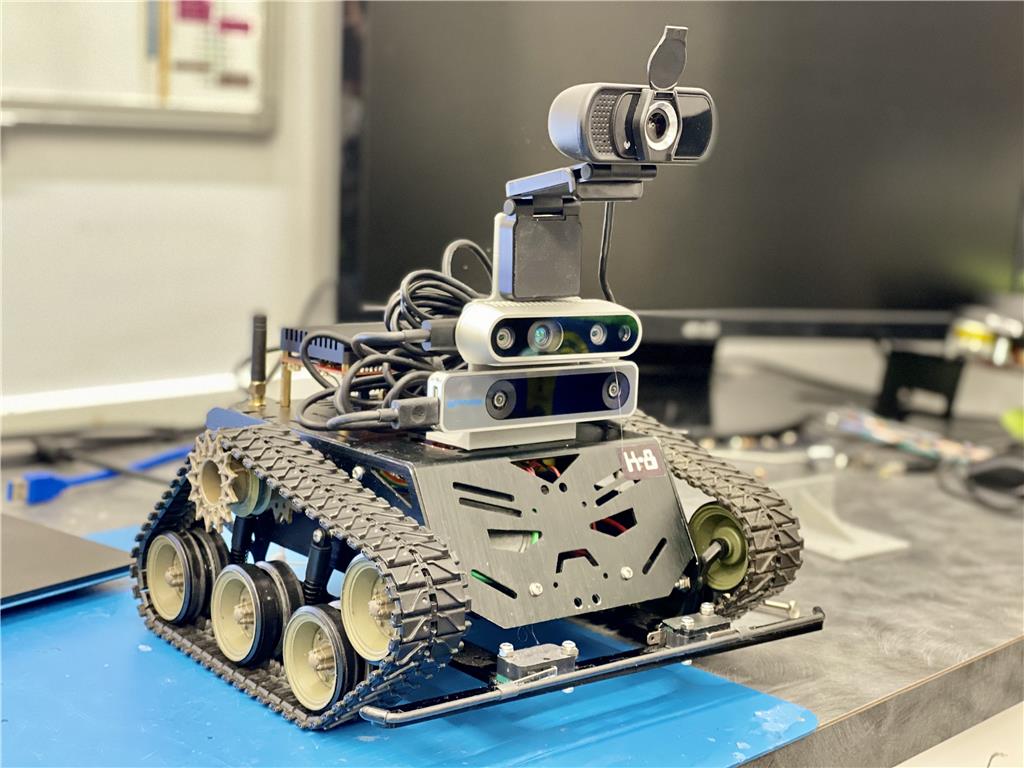
DJ's DJ’S Test Platform (K8)
Synthiam ARC test robot: Devastator tank with Rock Pi/X, Sabertooth+Kangaroo, Realsense D435i/T265 for autonomous...
Adfe74's Meet Suki 6Dof Leg Dynamixel Ax-18A
SUKI 6-DOF biped uses inverse kinematics, IMU for future balance, blob-based ball tracking, gait sequences with dampers...

Very cool RobotHappy,
Where did you get that base? I'm assuming it has 3 wheels?
Thanks,
Bill
@EEG Hello, and thank you. The base itself is from Parallax, Inc. Its their two wheeled base with casters. I got it when they use to call it the Eddie bot series, and now they call it the Arlo series. The entire idea of the robot was actually based on a book I first heard about from servo magazine. The book is "The robot you always wanted" by John Blankenship from Amazon.