Discover more robots
Steve's Grace’S First Robot
Boxbot dance demo built with 9-year-old Grace, a family robotics project fostering her interest in building robots
DJ's Darth Vader Humanoid Robot
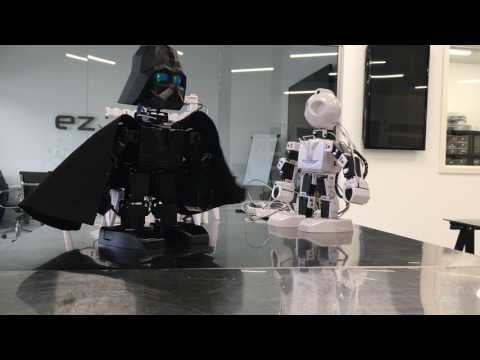
Darth Jader robot preview using old servos, short demo video showcasing movements ahead of The Robot Program episode.
Quantumsheep's Camera Robot Mk2
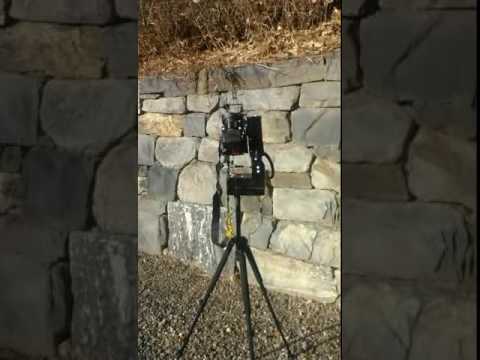
Travel-friendly foldable panobot supports 2.5kg DSLR, fits in a camera backpack and uses a refined app interface and...

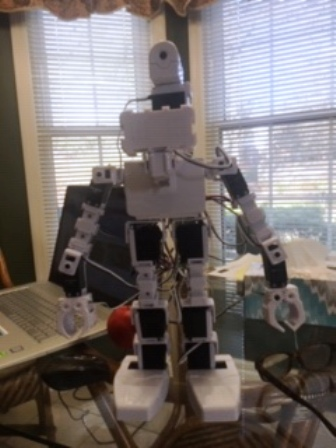
Looks good but for the walking , a trick we used way back on the really tall Robosapien RSV2 or Media bots,we added some rubber to the bottom of the feet to get more traction when it would slip on hard floors.
Great, I see I need more traction
Thanks
i would use the cube's to start trying to make a walking gait. it will be very hard to do with the large Extension Block.consider you dont us a gyro. with a big robot is also a good idea to make or use alu brackets insteadt of plastik ones, they tent to bend a little.look at many video about making walking gaits. see what all these robots do when starting to walk.NAO,WALKER,BIOLOID, they all do desame pose when starting to walk and that is bending the knees a little. also NAO name it the adaptive walk.jd bend his ankle on knee hight, all other robots have movement on the ankles forwart/backwarts/left/right.