I would like to make a "Robot Butler". This robot will balance and walk upright. It will scan for items left on surfaces that match visual patterns of eating-utility (paper plates, empty-cups, plasticware, napkins), and upon command would gather them up and drop them into a known-location (or tagged) trash container. It could also pick up tagged items that can be delivered to flat table-surfaces in the same room, similar to somebody serving drinks or food to people. It would also answer calls and talk to the caller to ask to take a message, based on the owner's current activity.
By Firstlily

Discover more robots
Ezang's Some Examples From The Past Of Glyphs, Glyphs With...
Glyph examples with augmented reality and QR codes using a USB camera and the EZB4 with camera and sample code
Keithjmoore's My First Robot
iRis telepresence robot: a first DIY build in progress to serve as a telepresence platform for work.
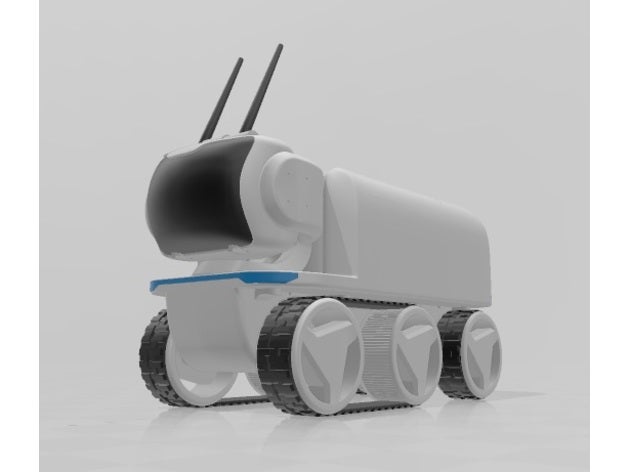
Jstarne1's Calling All 3D Printers! Get The Stls While They...
LEVi Rover 3D files assembled and ready to print, with model cuts for smaller beds and community tips for printing and...
