
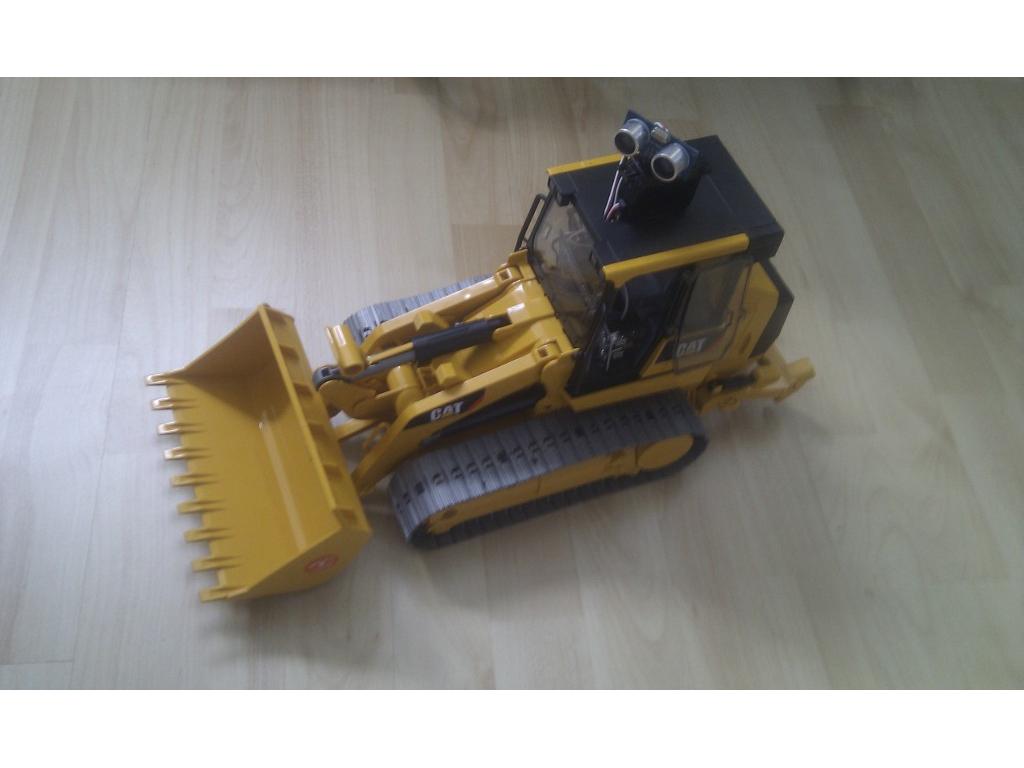
I got my EZ-Bot last week and this weekend I started with my first project. I got myself a nice Caterpillar toy:
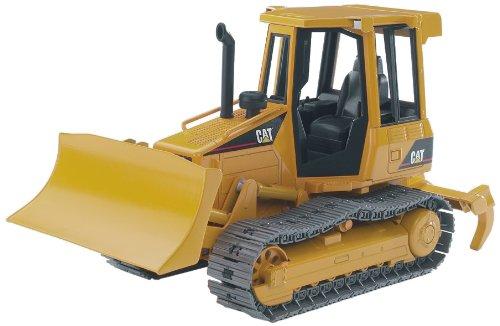
And, as far as I can tell from other posts here, in good EZ-Bot tradition, started to disassemble it right away.
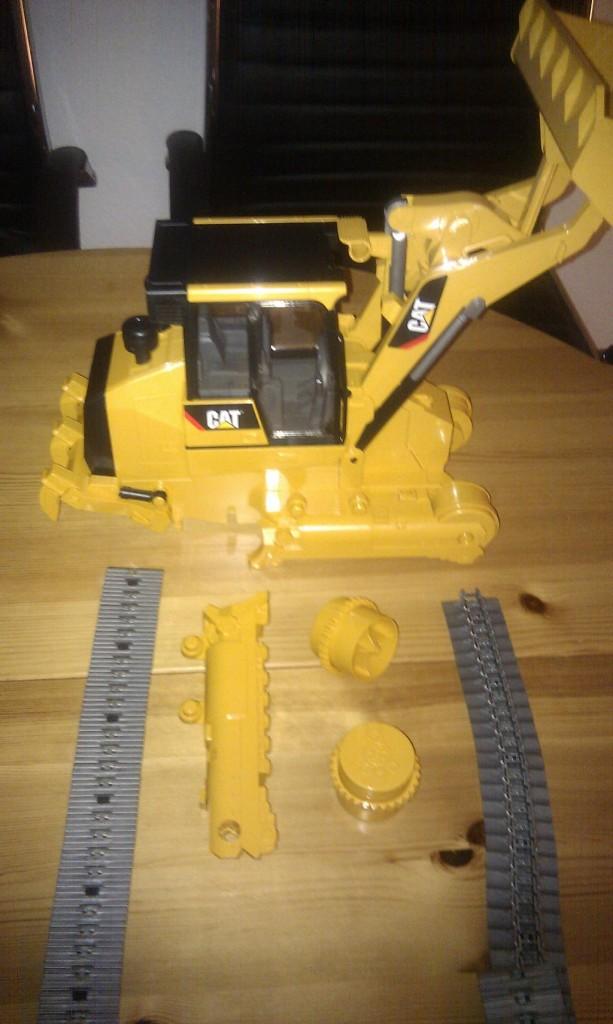
After just slight problems with dremeling, I cut a hole in the bottom for the continuous servos that will drive the treads. I couldn't believe how close the servos fit in there.
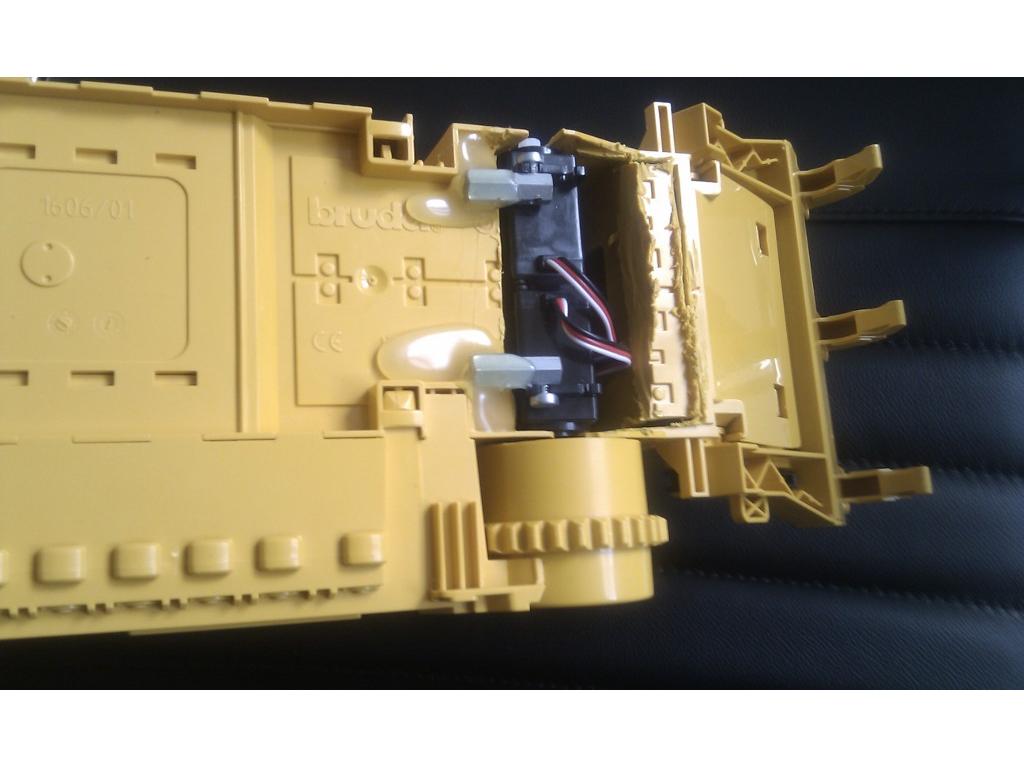
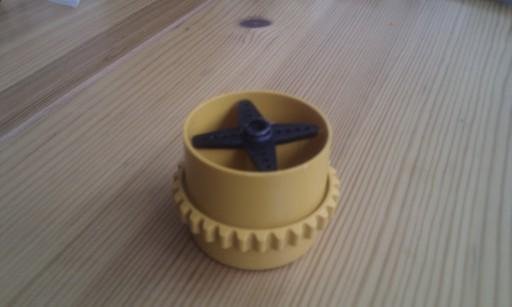
Hotglue the servo horn to the driven wheels
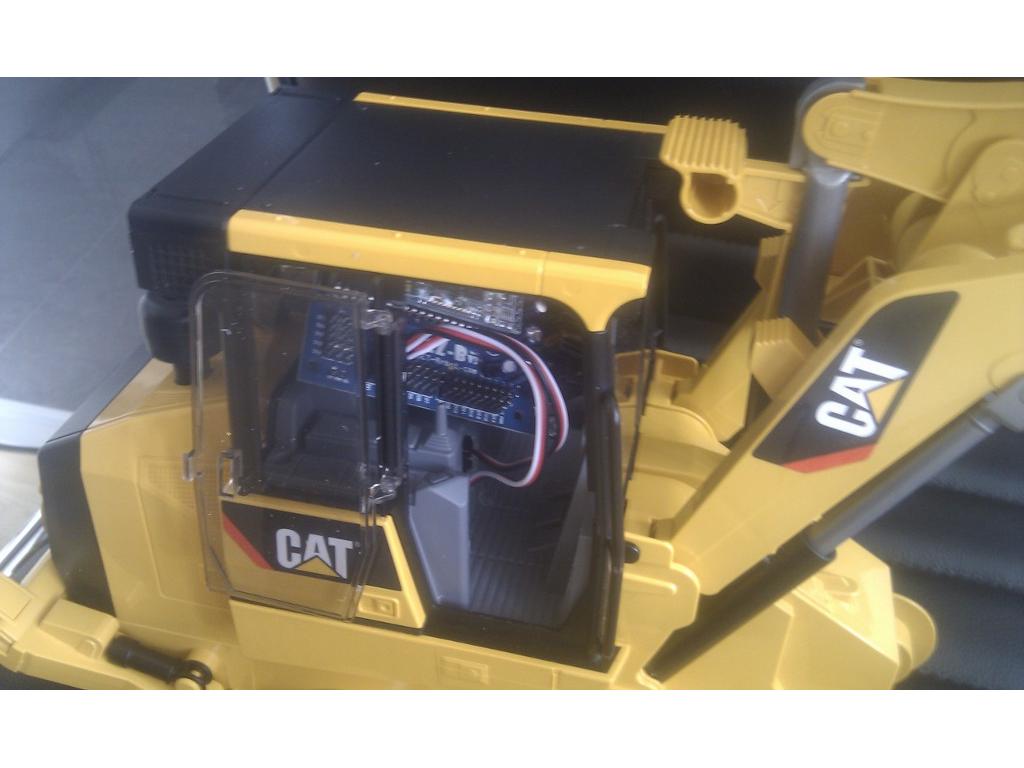
A hole for the cables into the cabin and we're good to go!
By peterfrisch
— Last update
Discover more robots
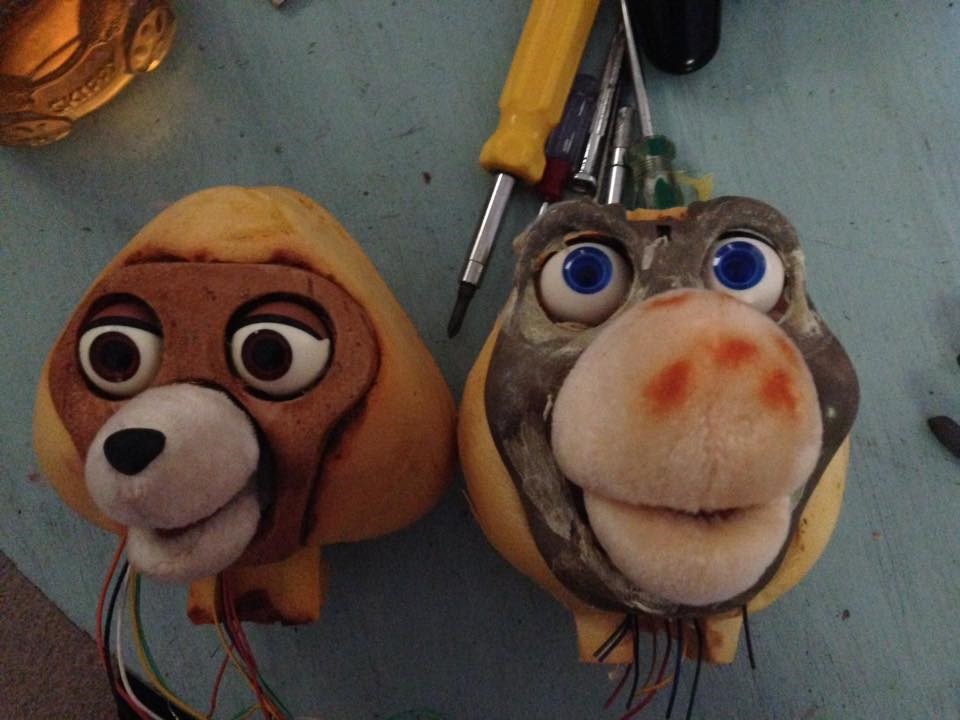
Sweetn8's Teddy Ruxpin And Grubby
Restore Teddy Ruxpin and Grubby with EZ-B v4: lip-sync speech, eye/mouth/head motion, mobile wheelchair/roller-skates,...
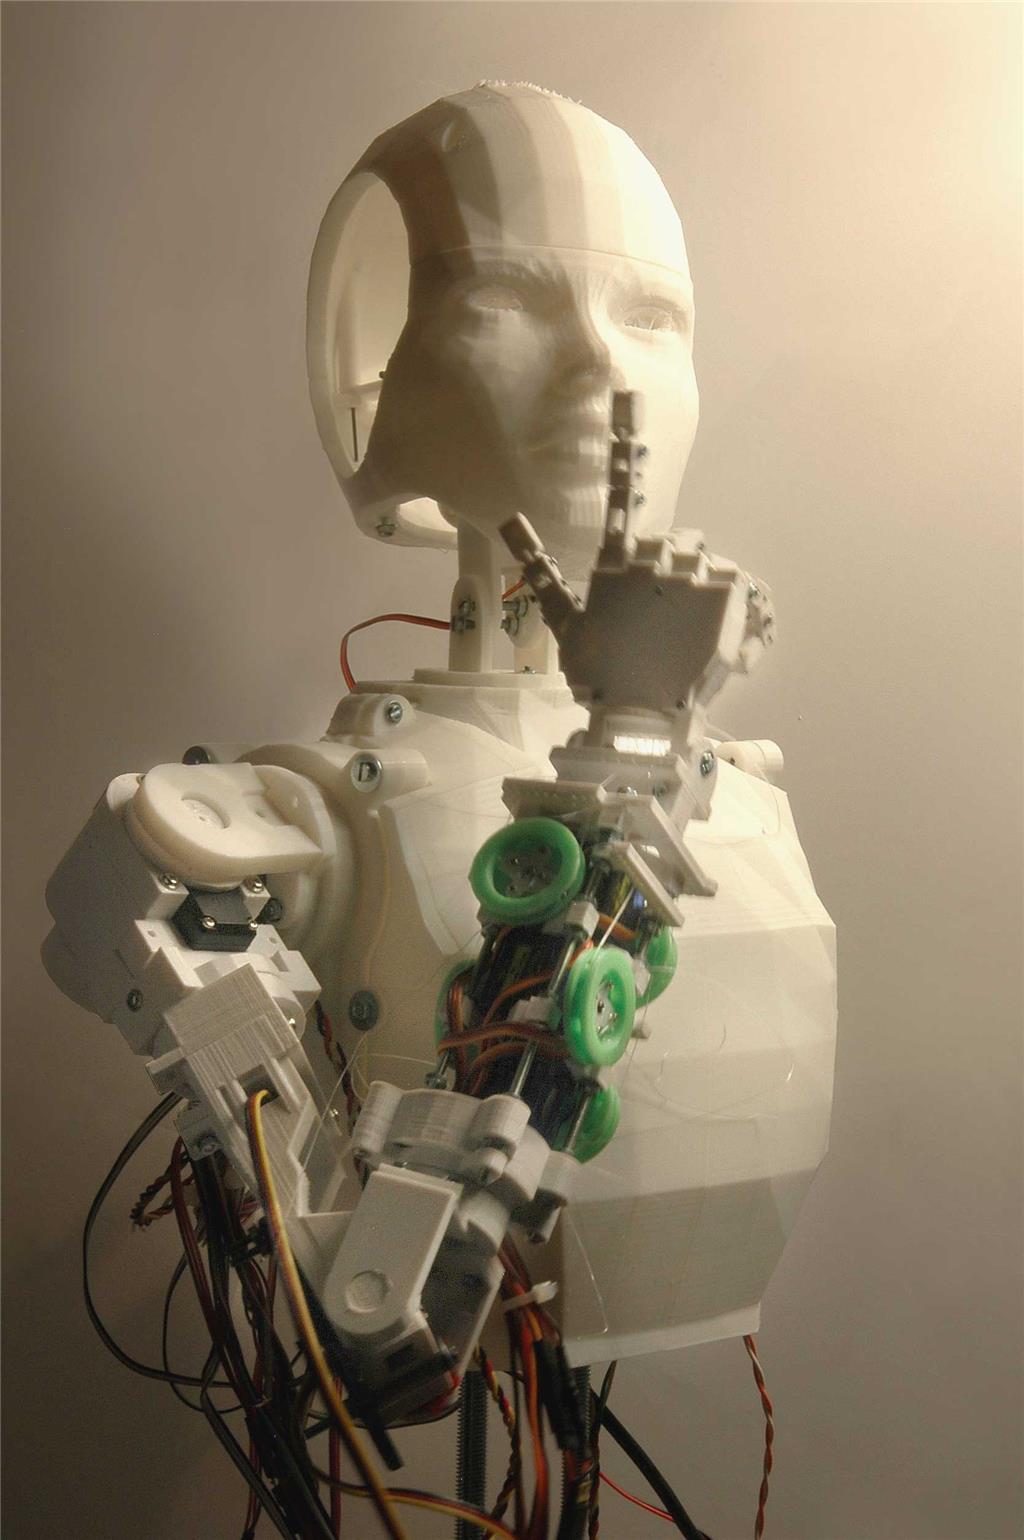
Buratino's Buratino - Humanoid Animatronic
Buratino 50x50cm 3D-printed humanoid with 23 DOF, heavy-torque servos, EZB camera motion tracking, speech recognition...
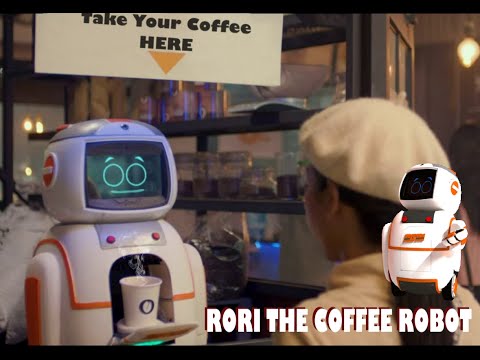
Ericez's Rori The Coffee Robot For Movie
DIY low-cost robots and tutorials: donated EZ-Board enabled 3D-printed Rori coffee robot for an Indonesian web series,...

Sorry, we go off the forum for the german discussion.
As a short summary: Sven and me both have problems with the voice control. The commands are just not recognized. Sven thought it might be because of his german win 7, but I use an english one, so that's probably not the reason. On the other hand: I got very few commands through to my bot, while none of Svens were recognized. So in my case it might just have been a bad microphone, where in Svens case it seems to be a more fundamental problem.