cE9s4PsOgeBQIORwjd5!~~60_1-634818020230156250.jpg)
Lupuc4g~~60_35-634706297915000000.jpg)
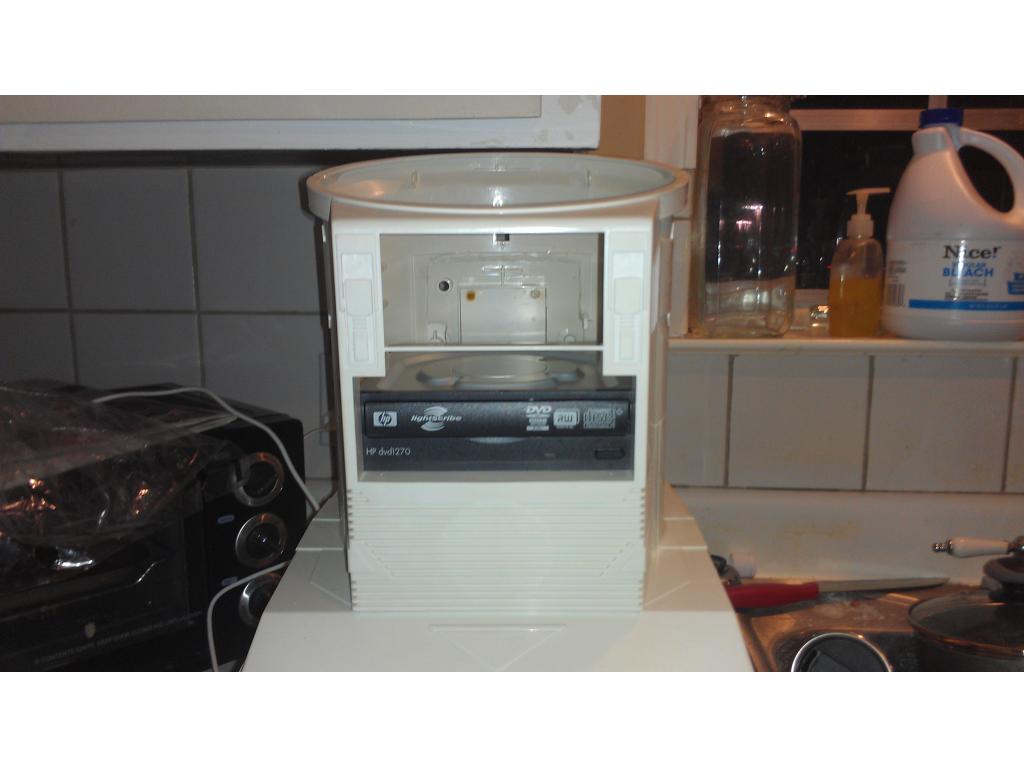
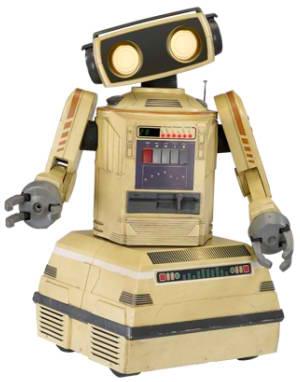
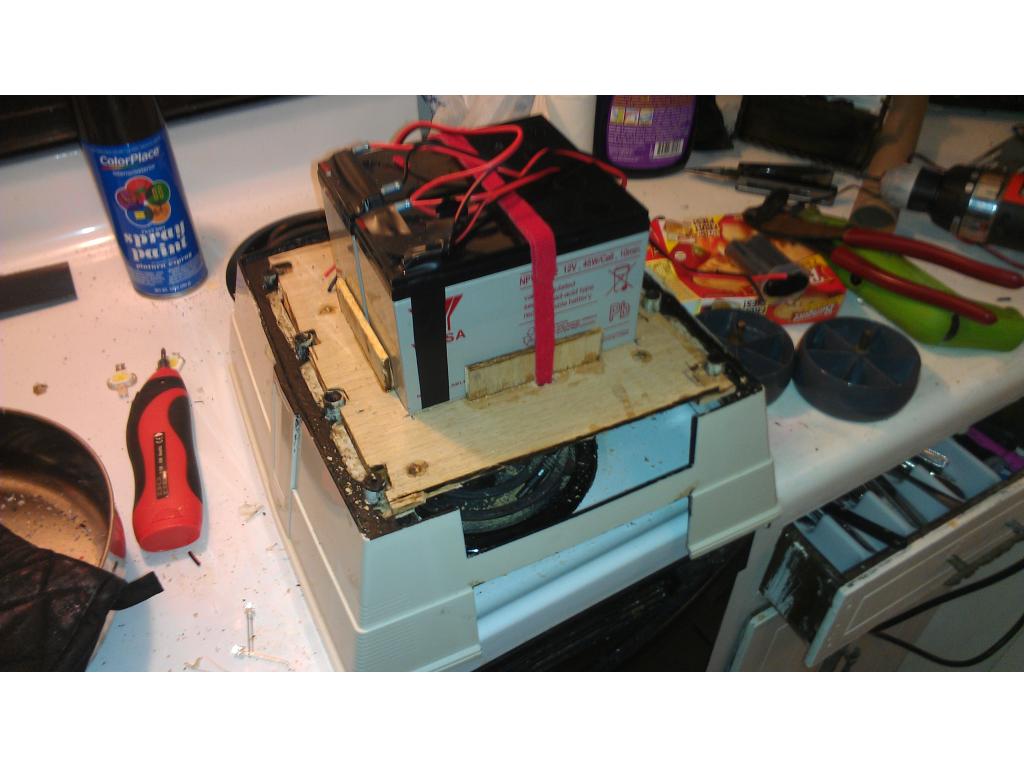
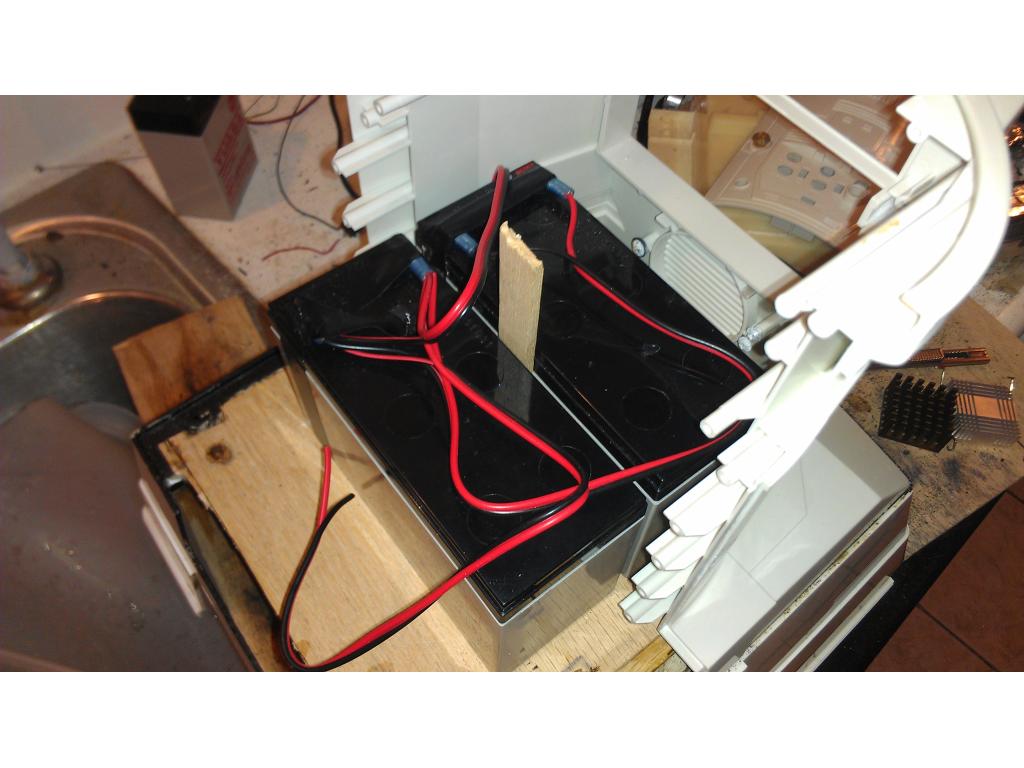
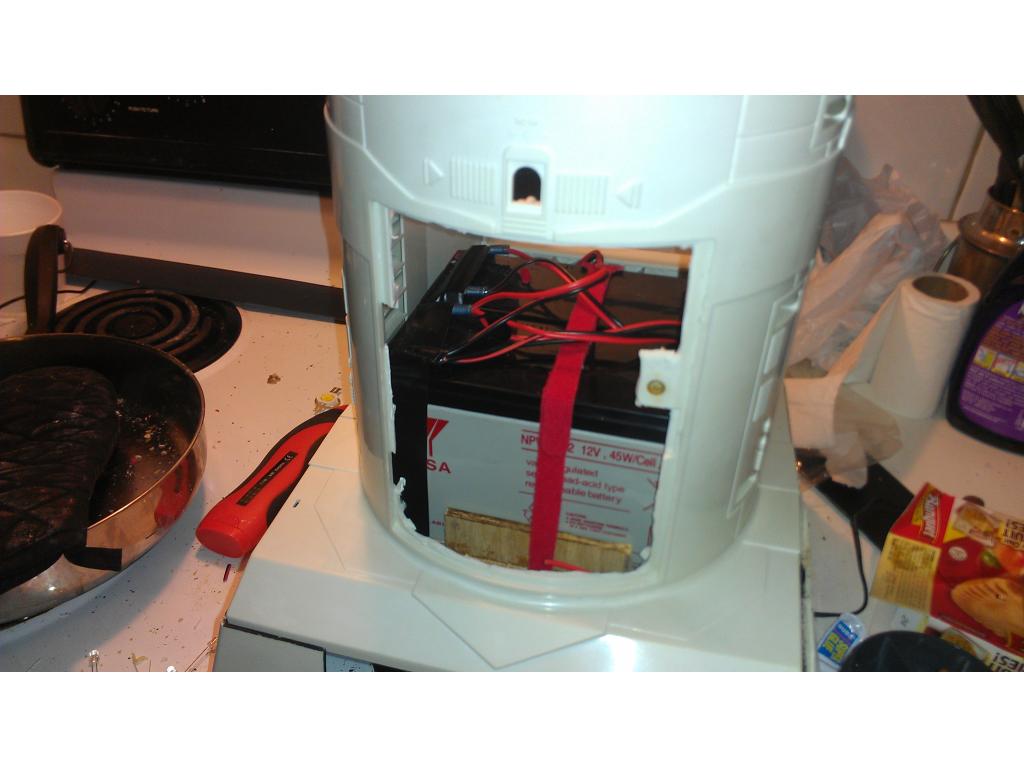
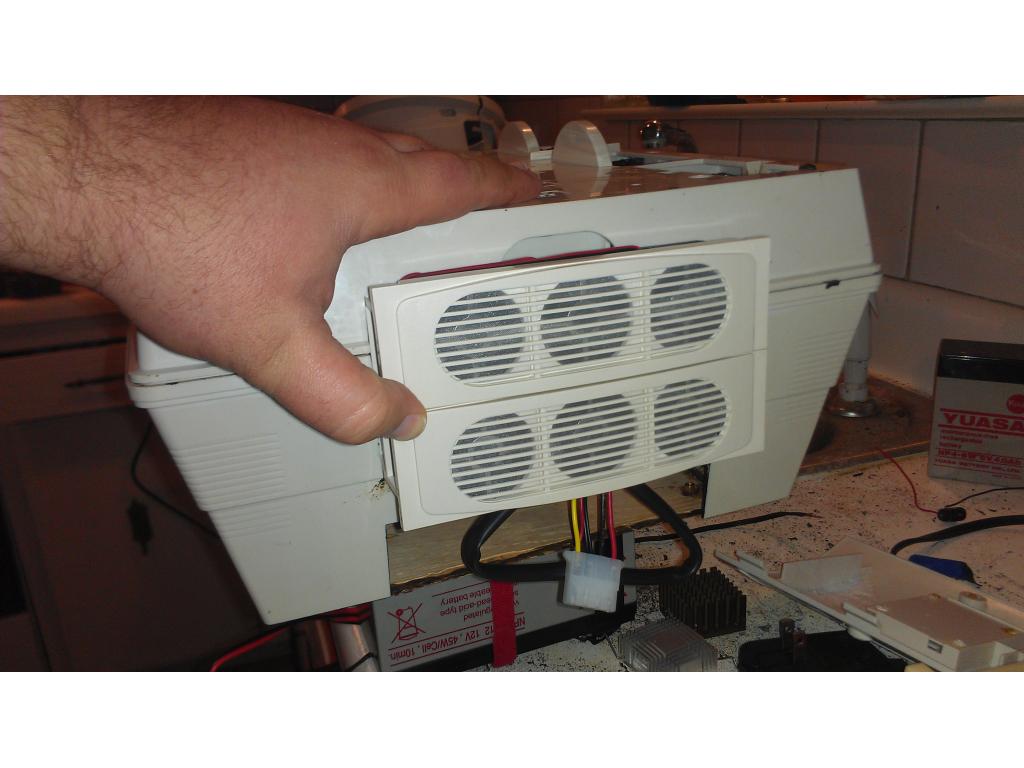
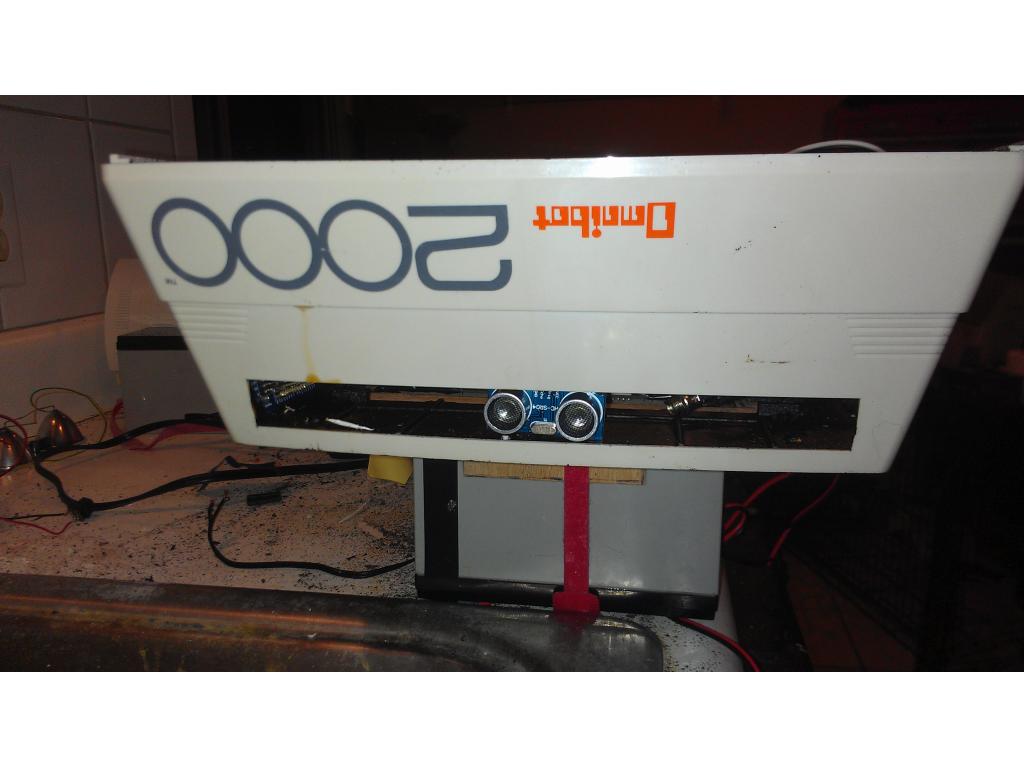
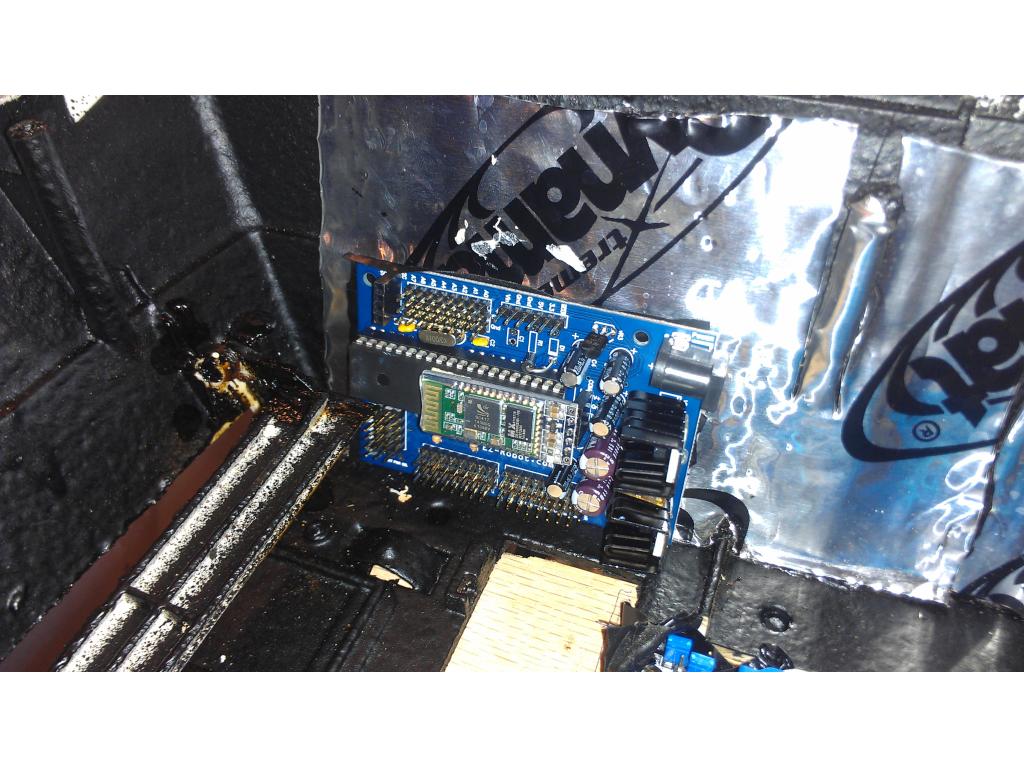
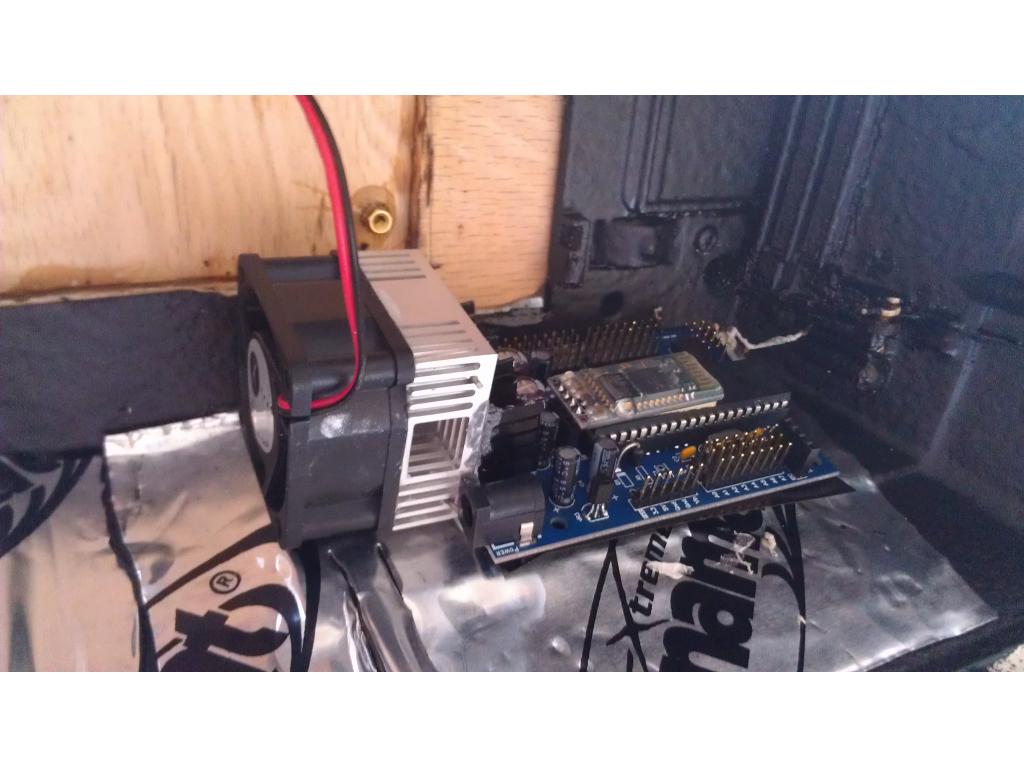
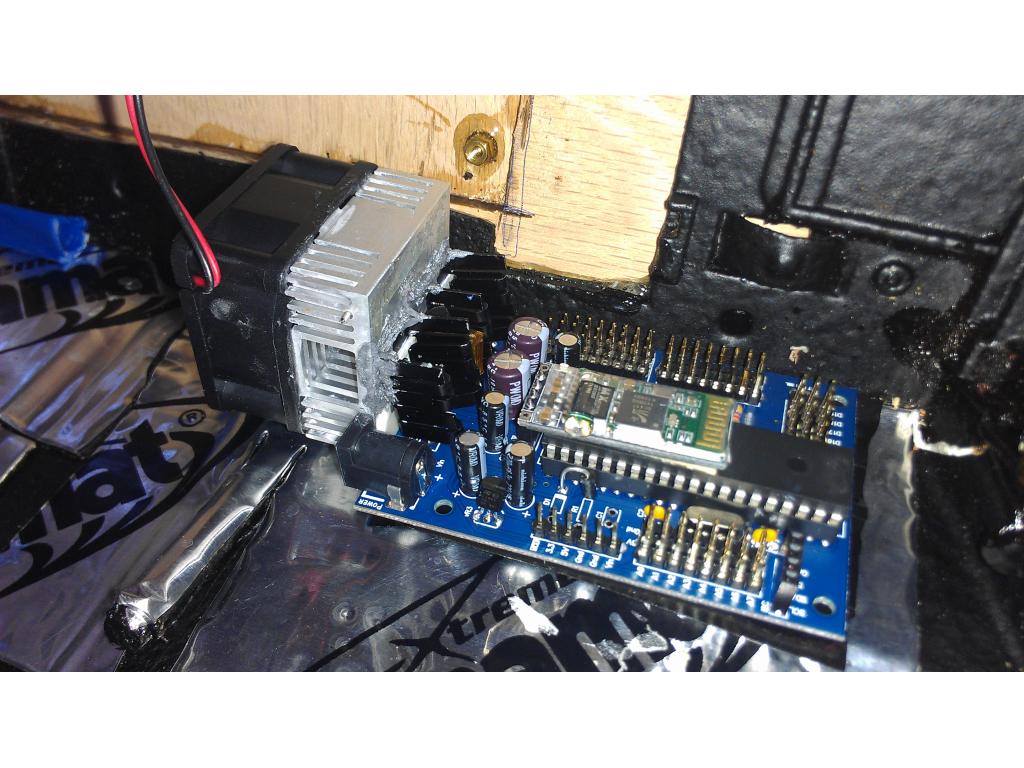
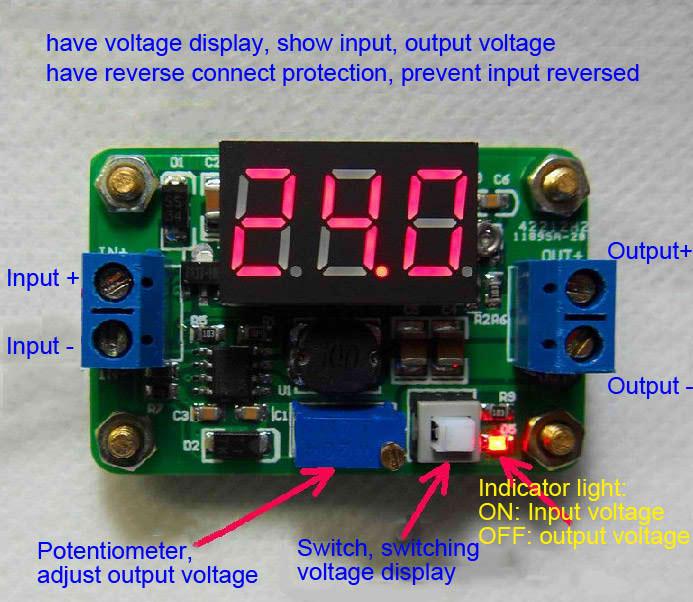
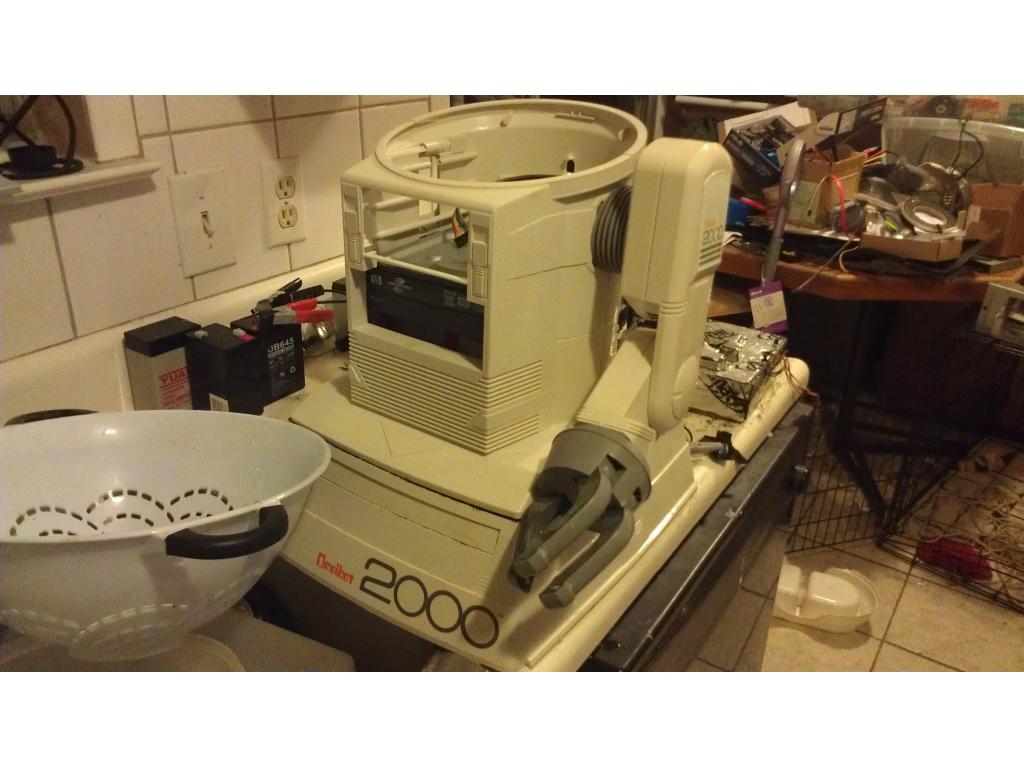
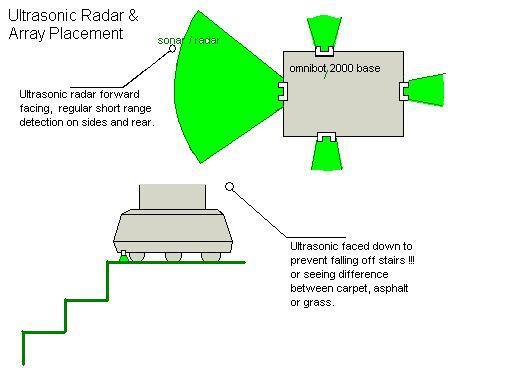
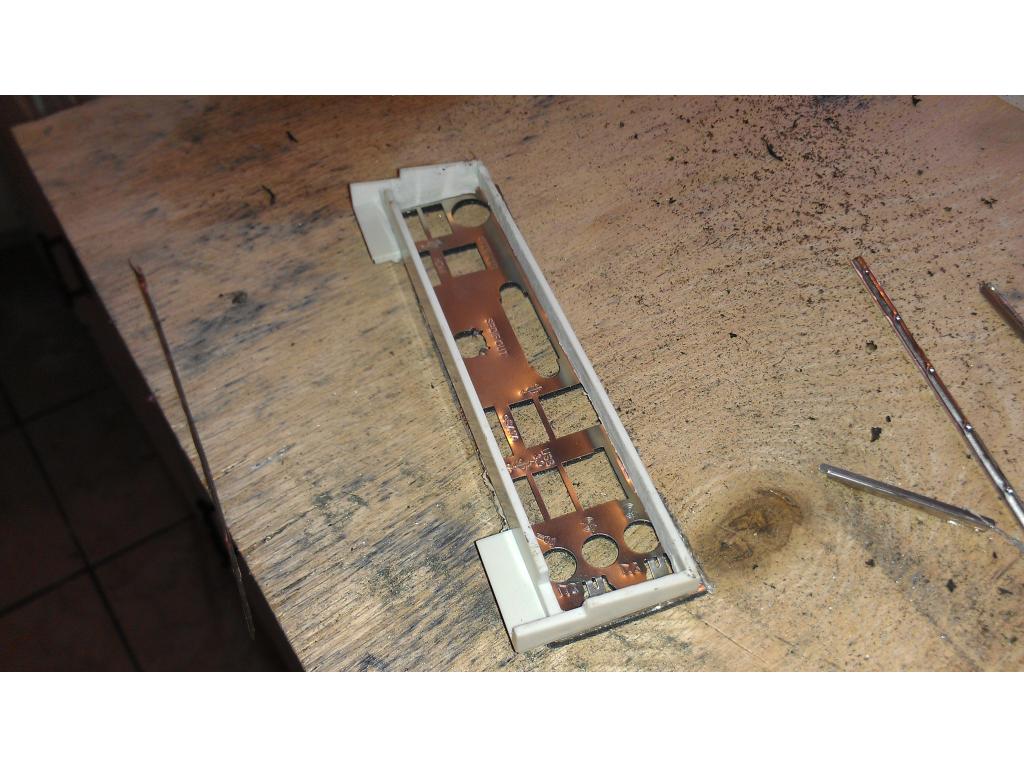
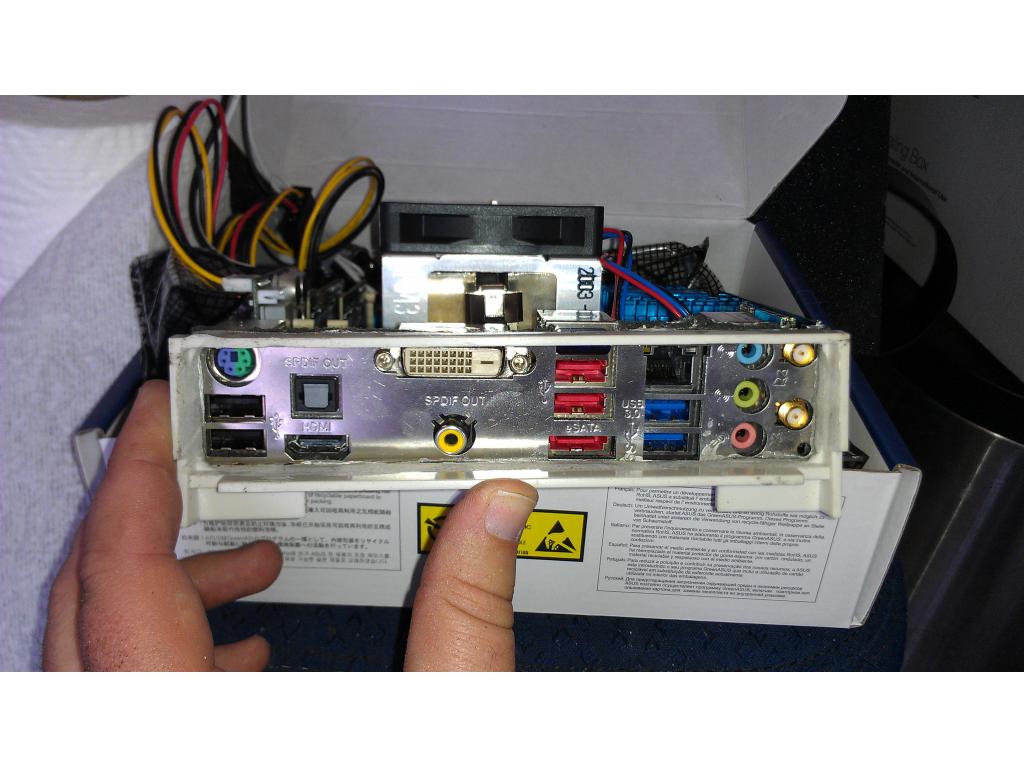
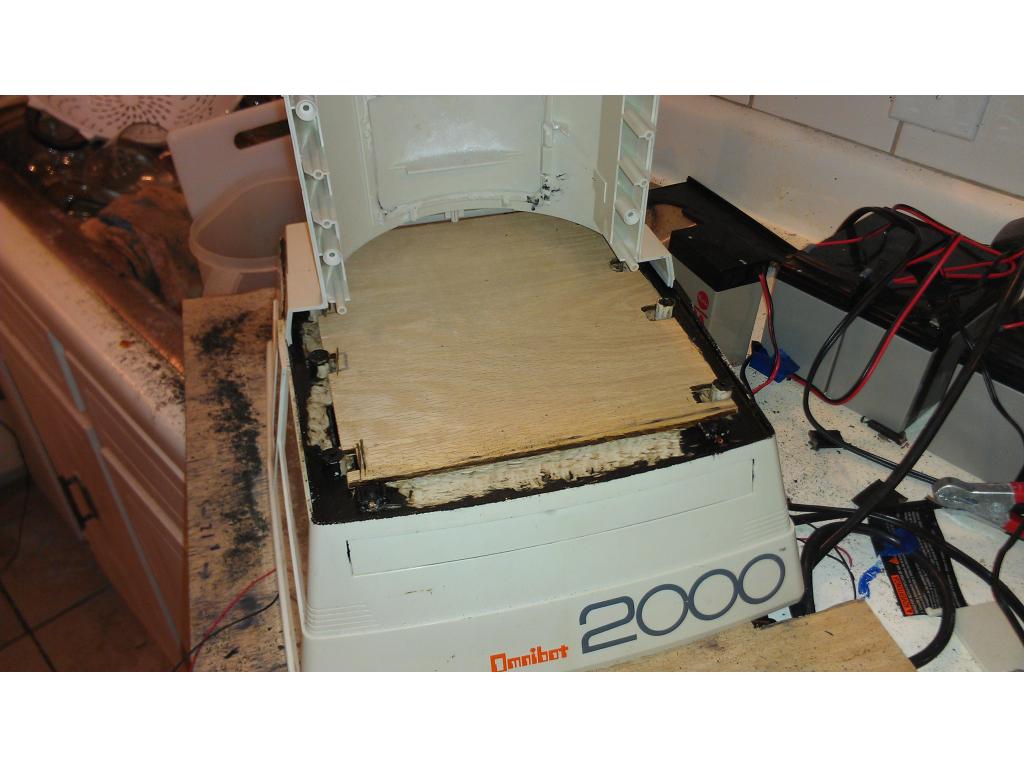
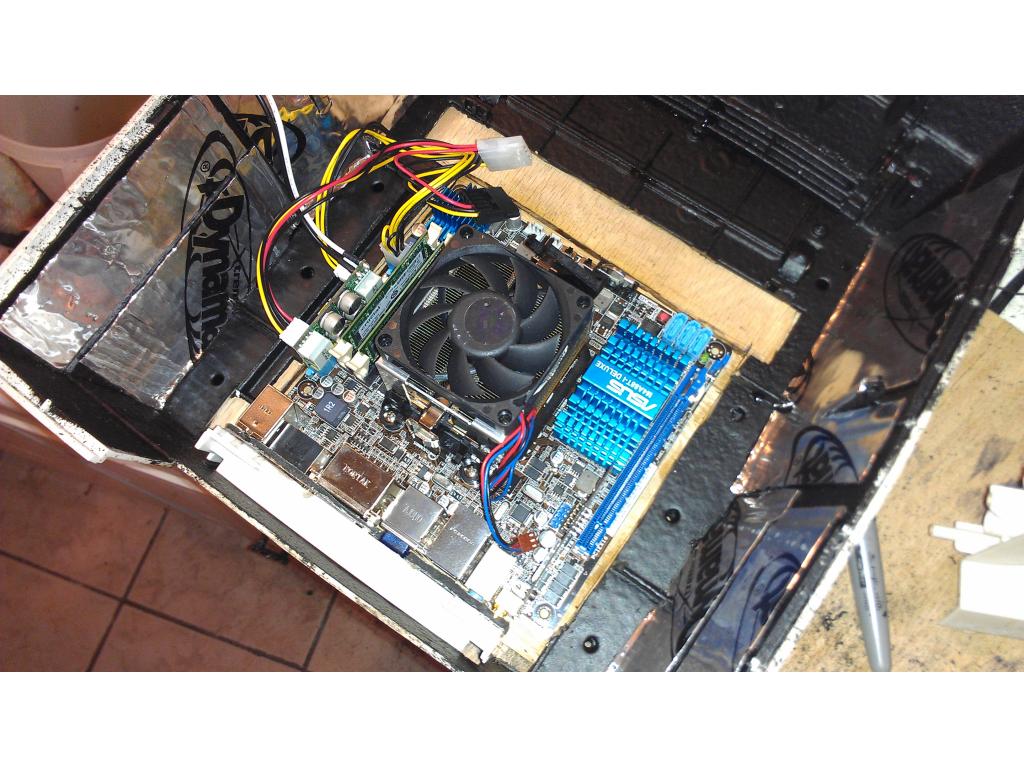
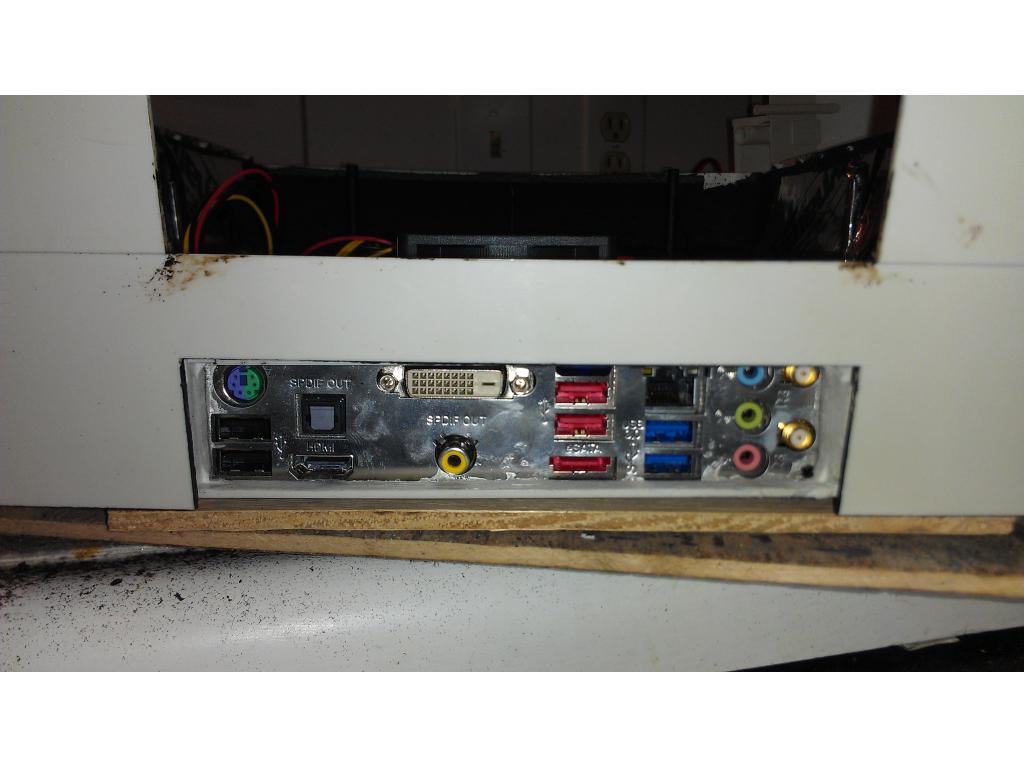
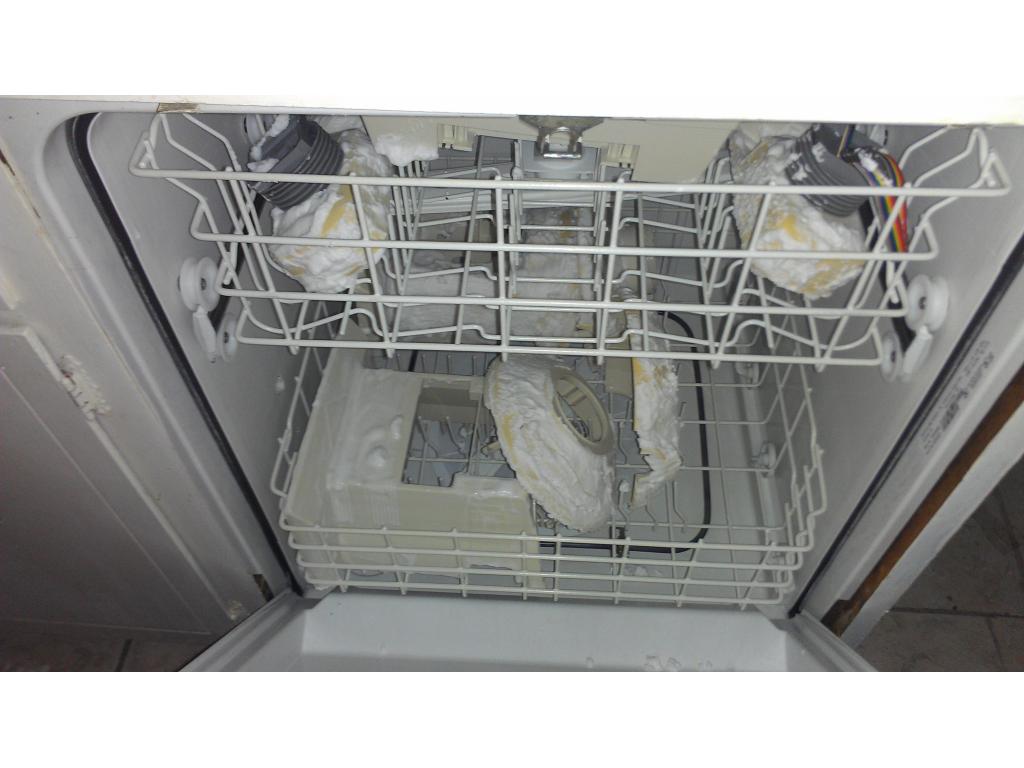
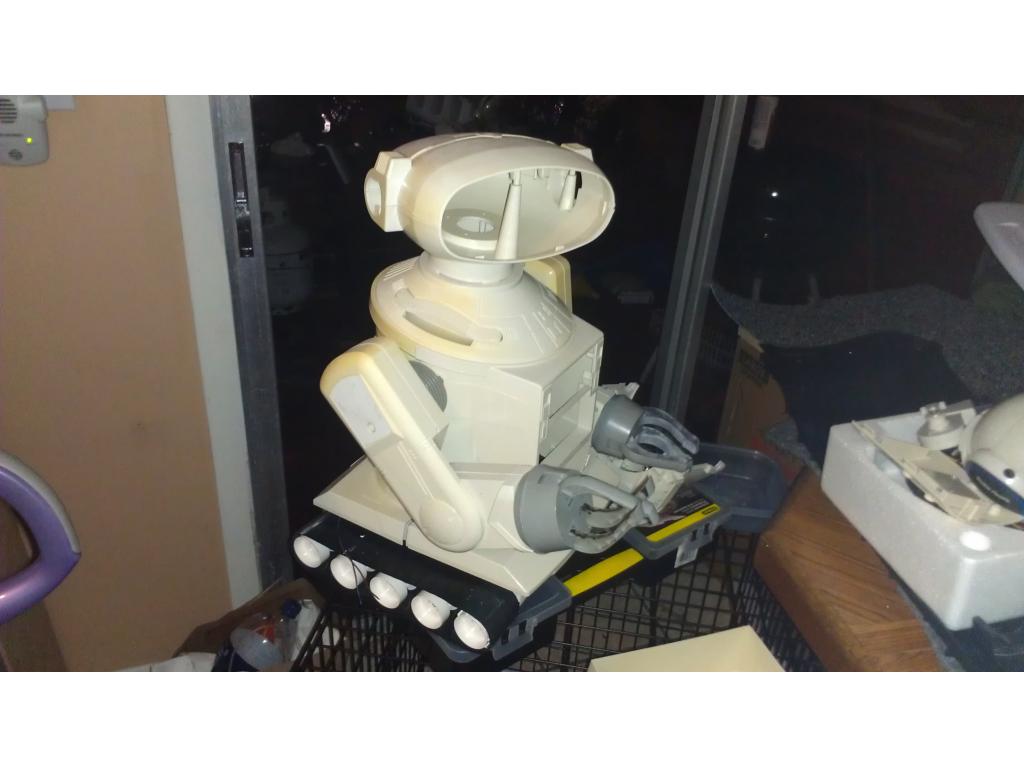
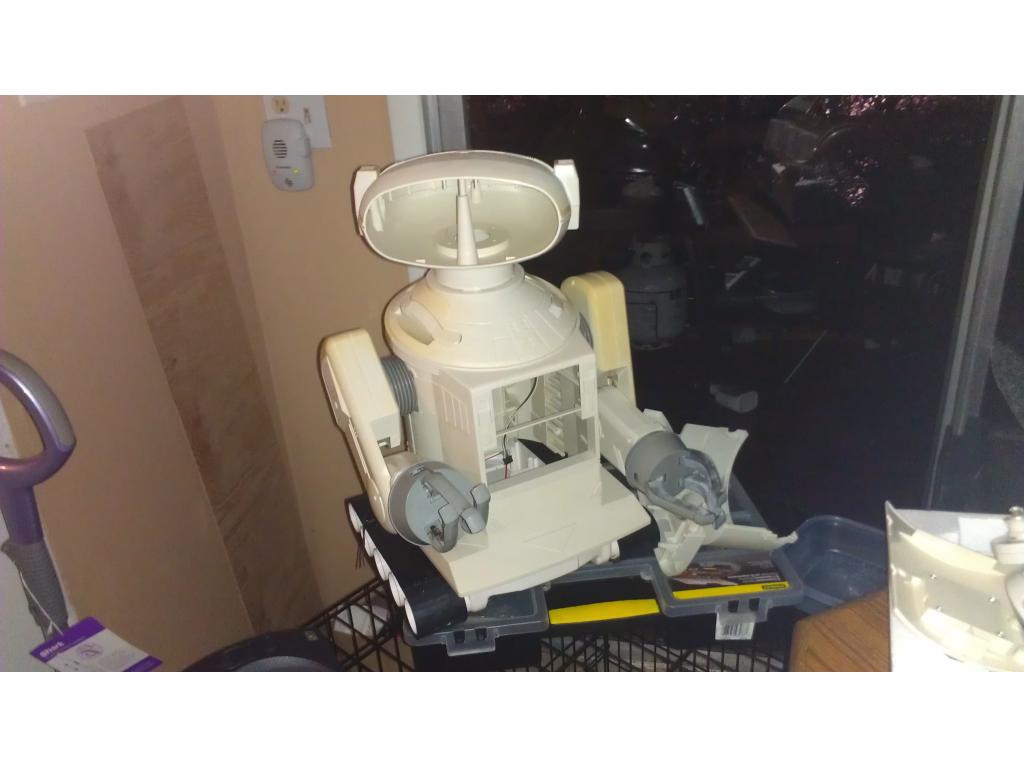
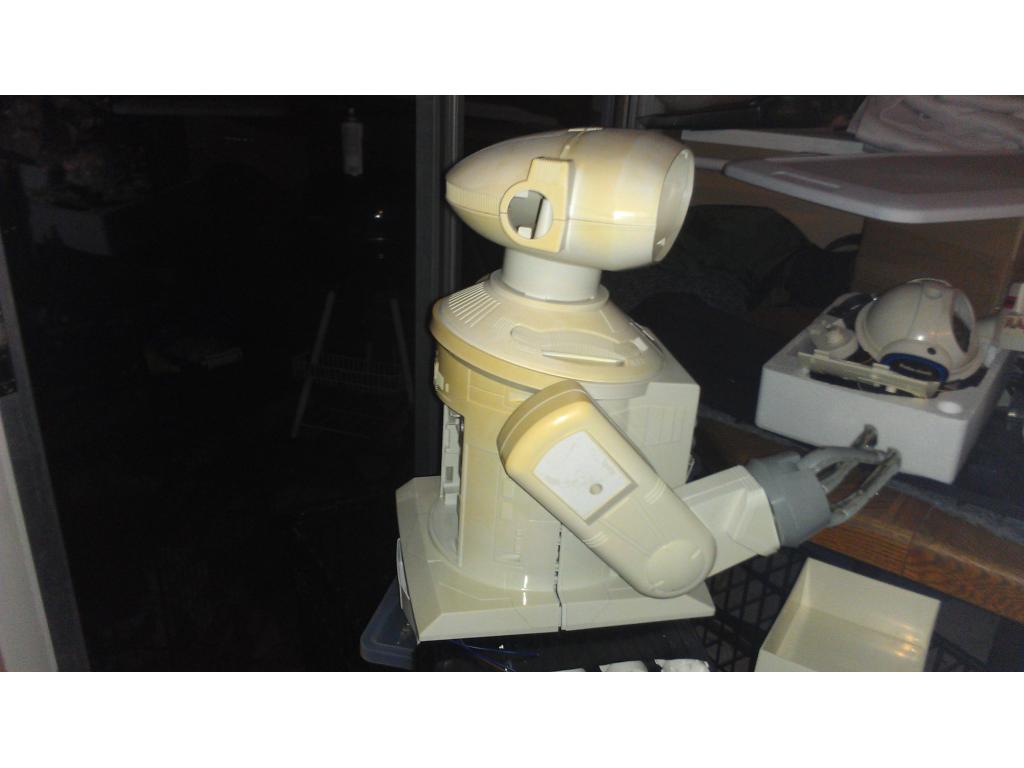
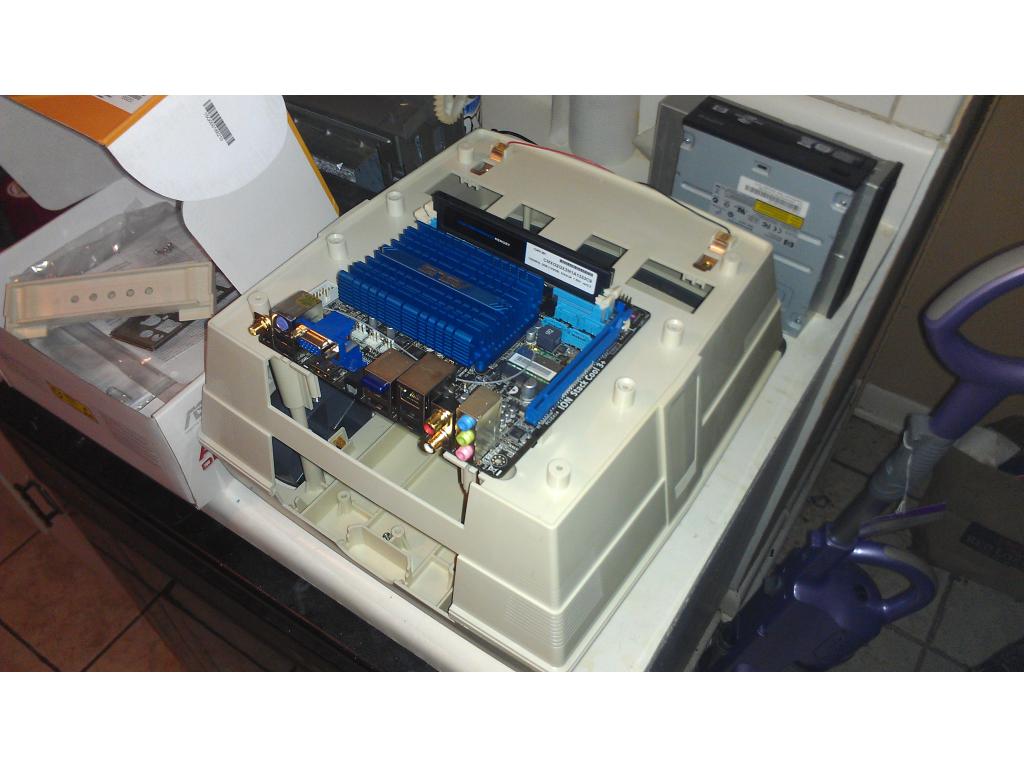
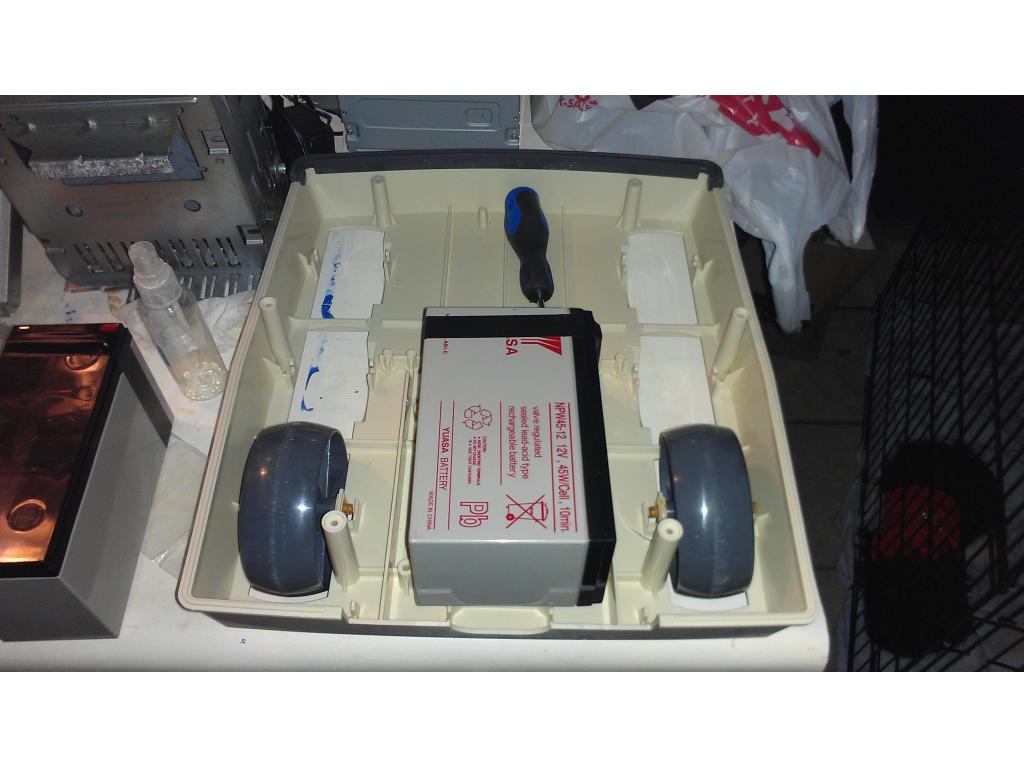
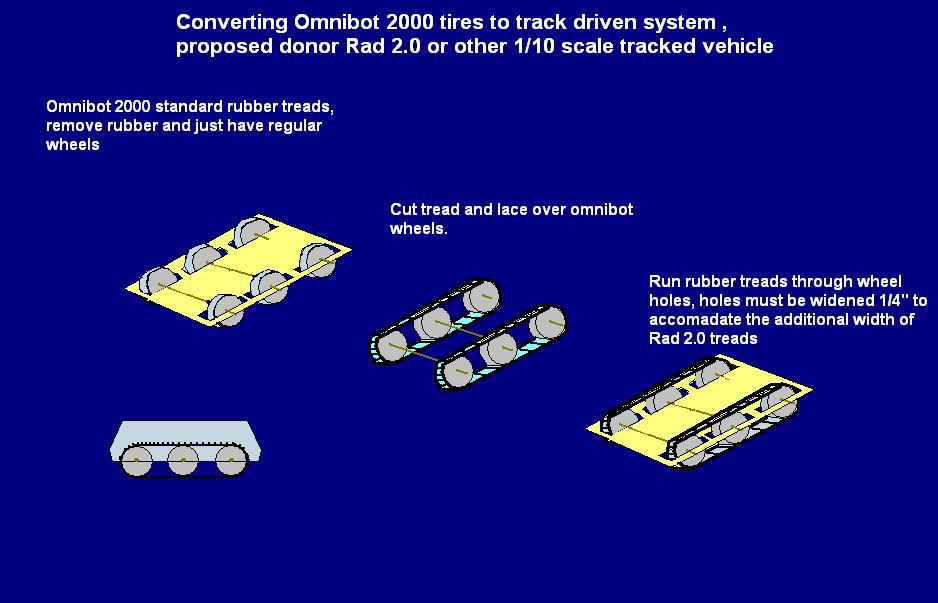


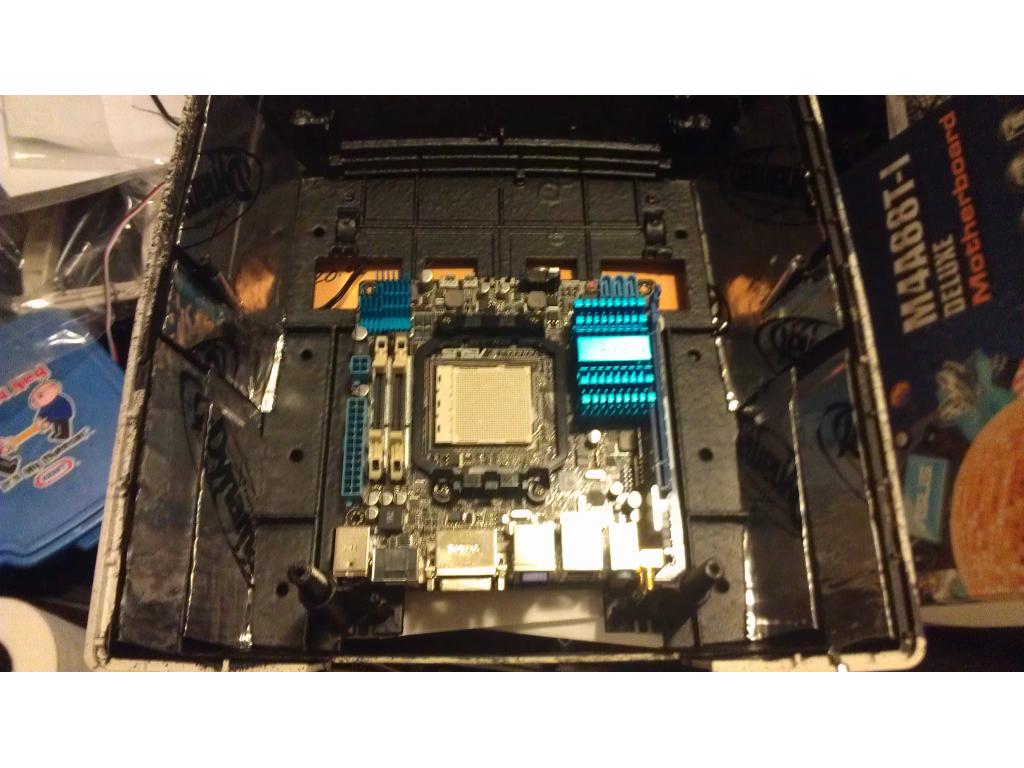
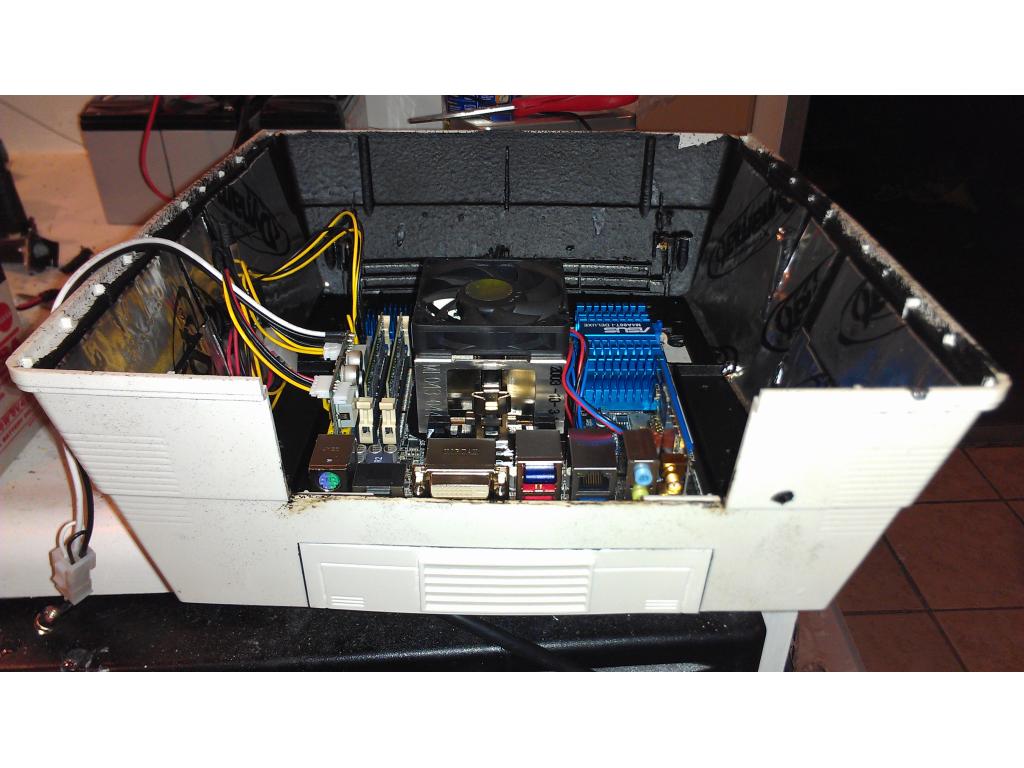
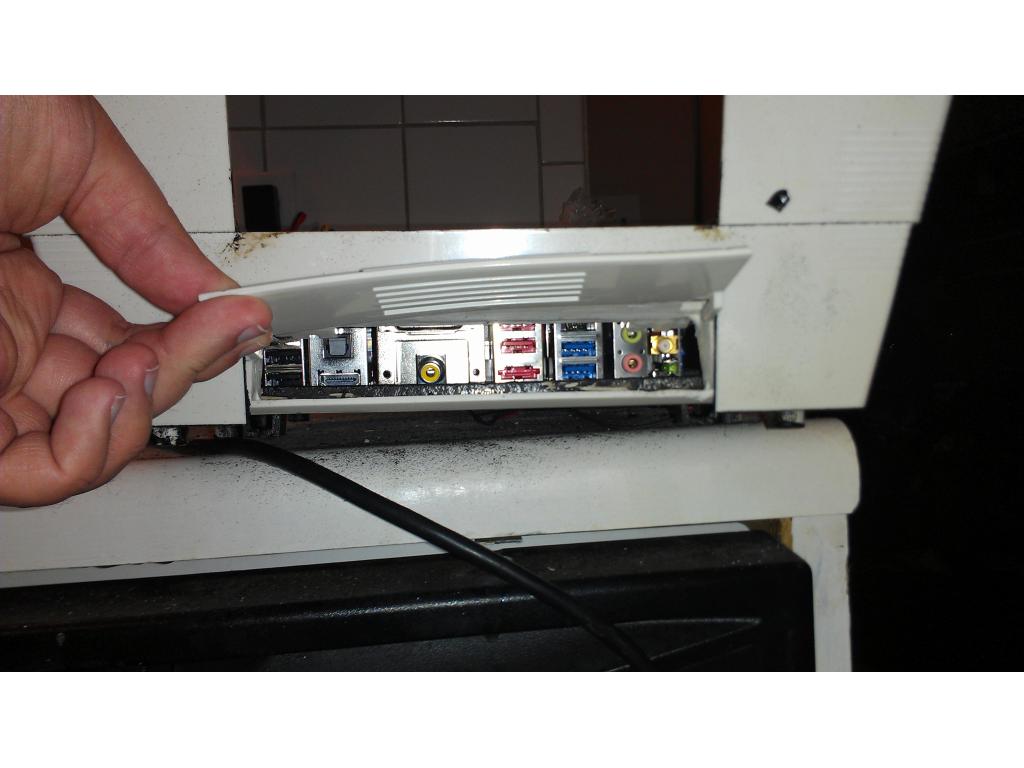
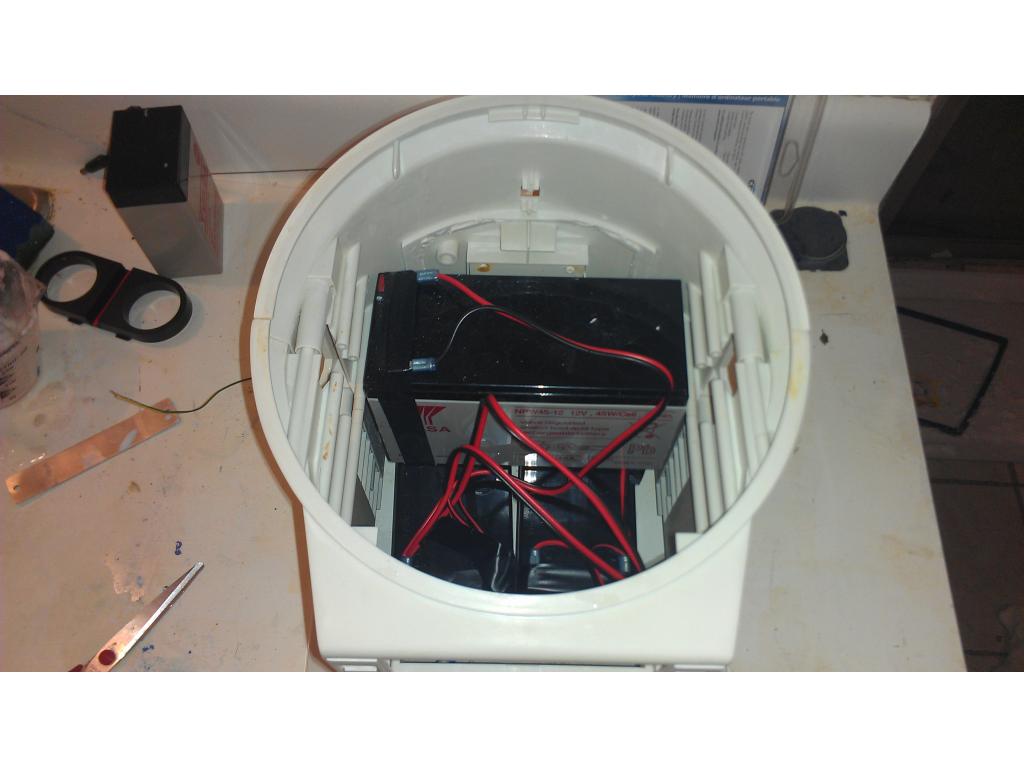
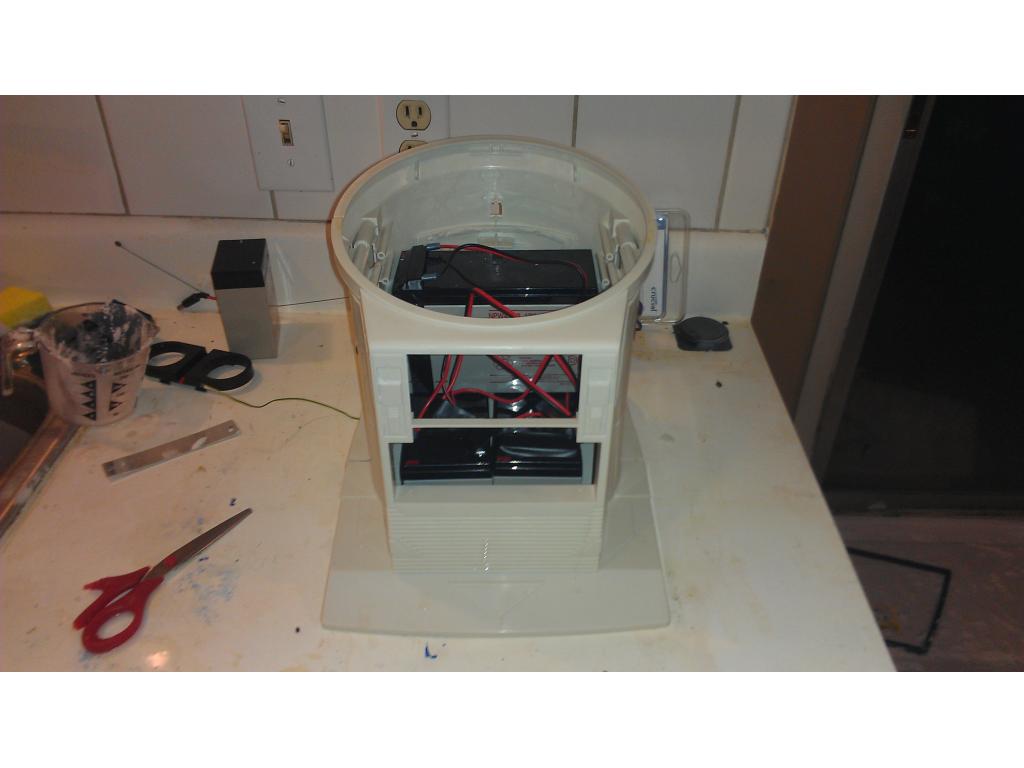
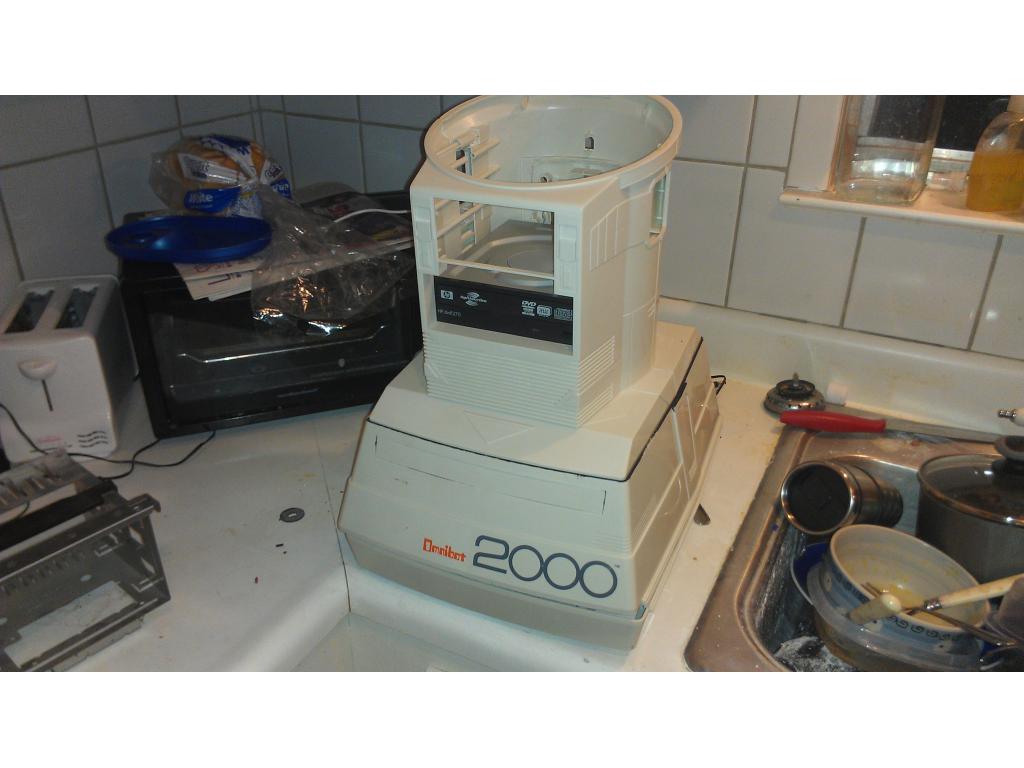
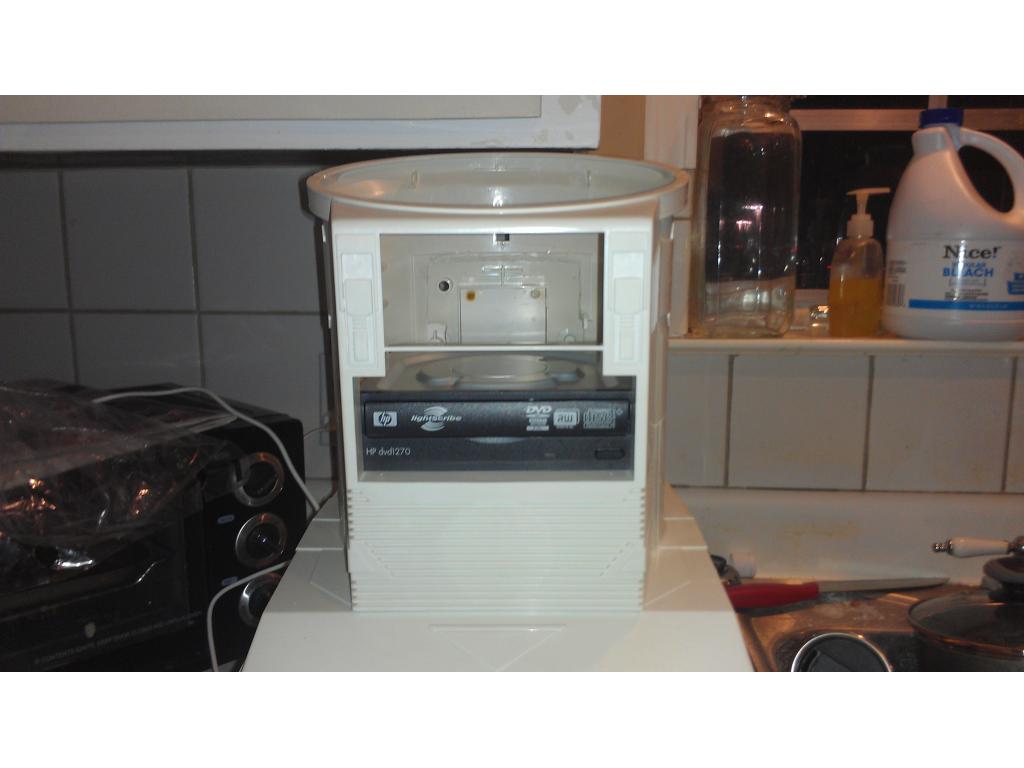
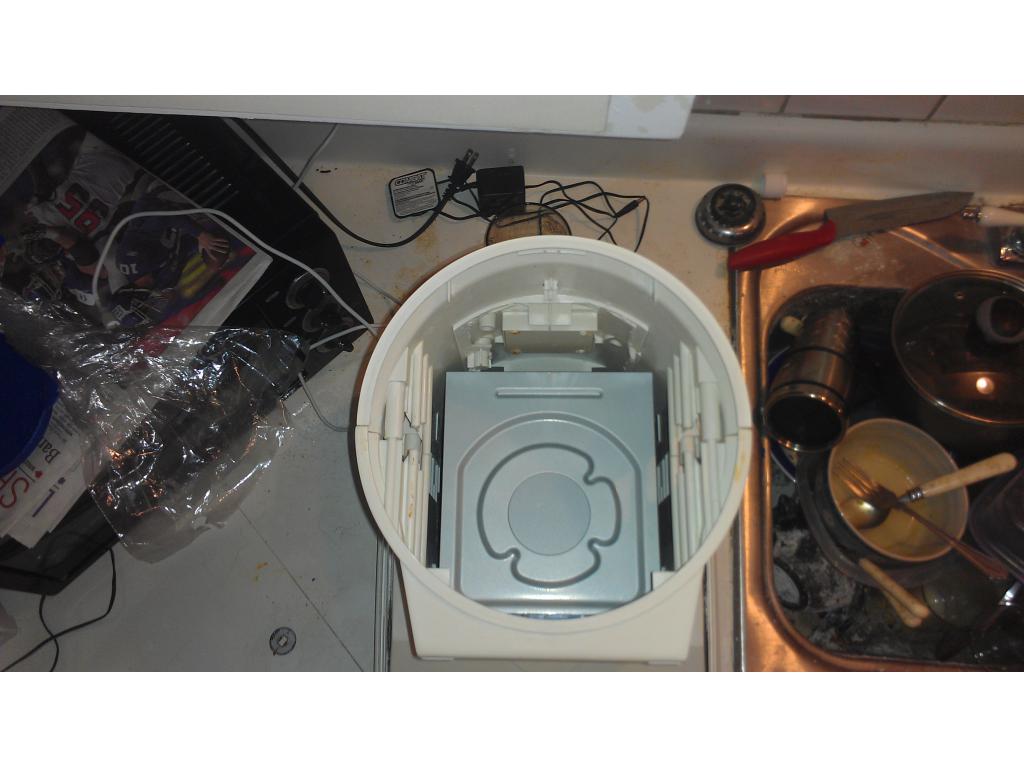
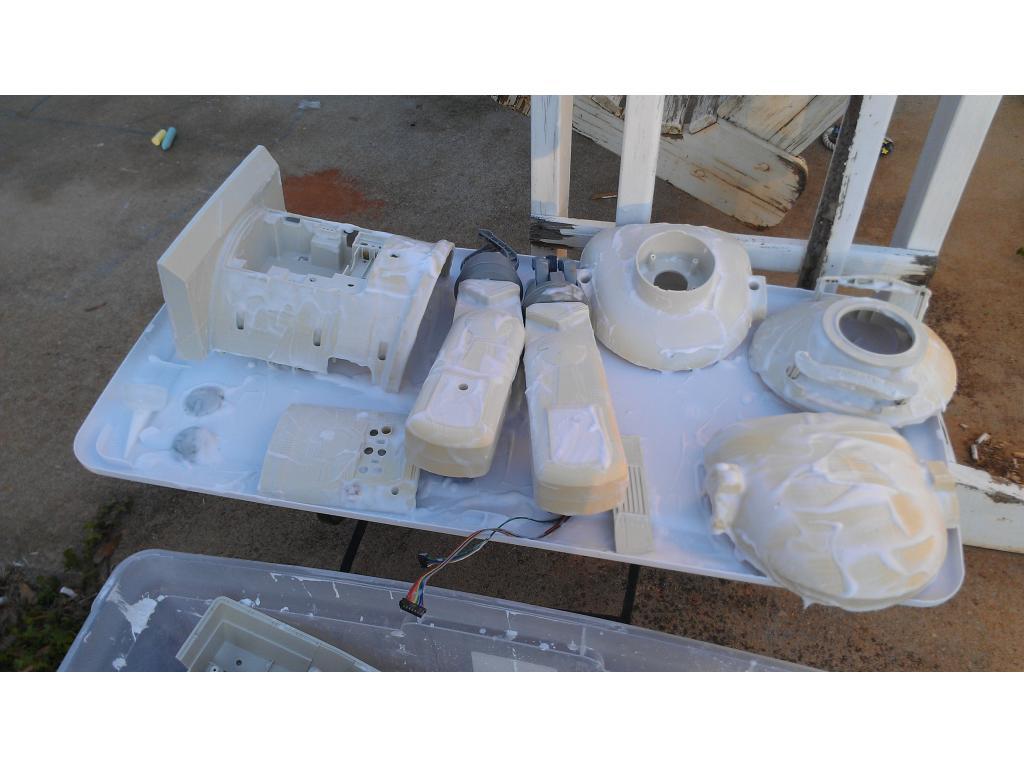
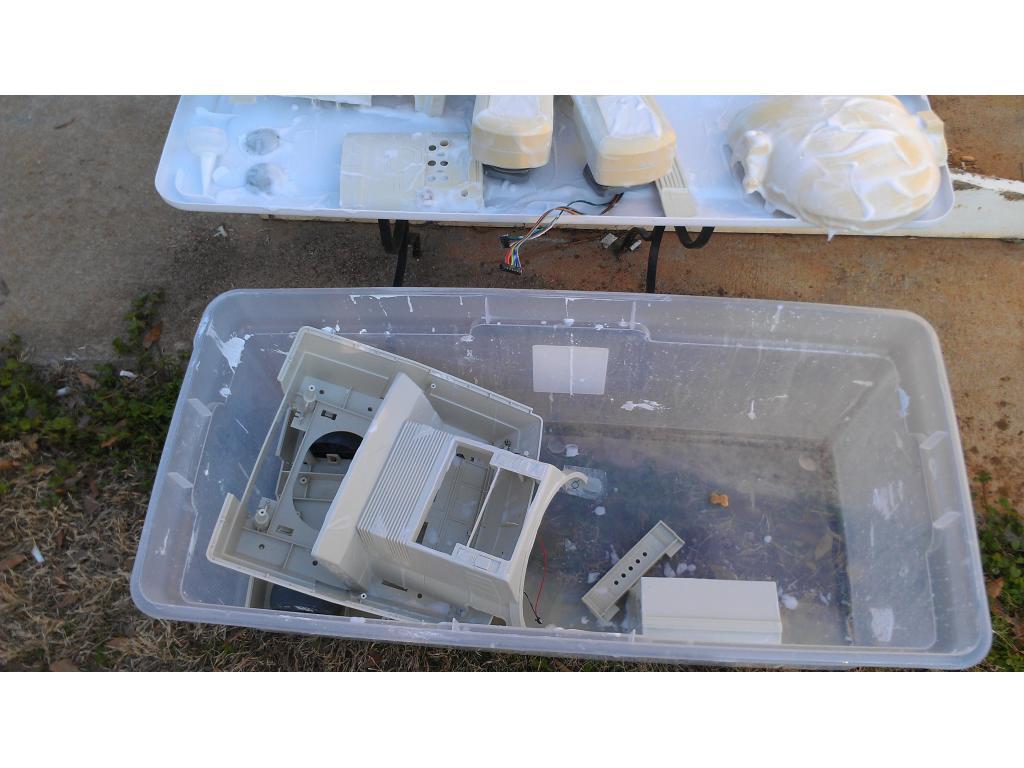
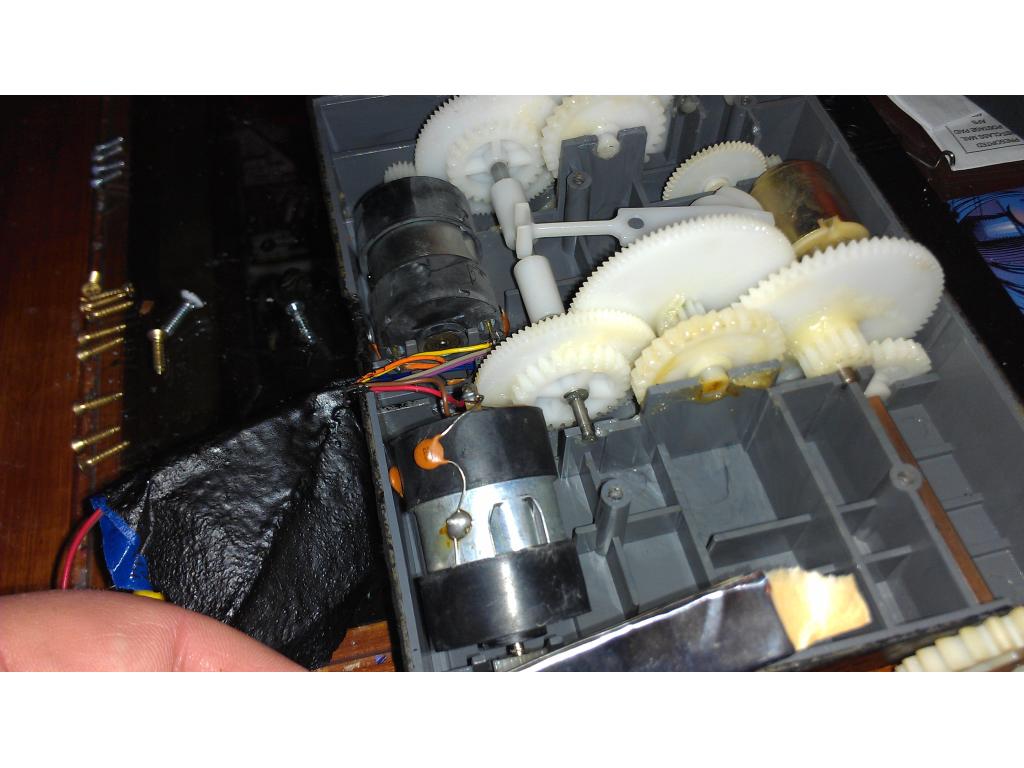
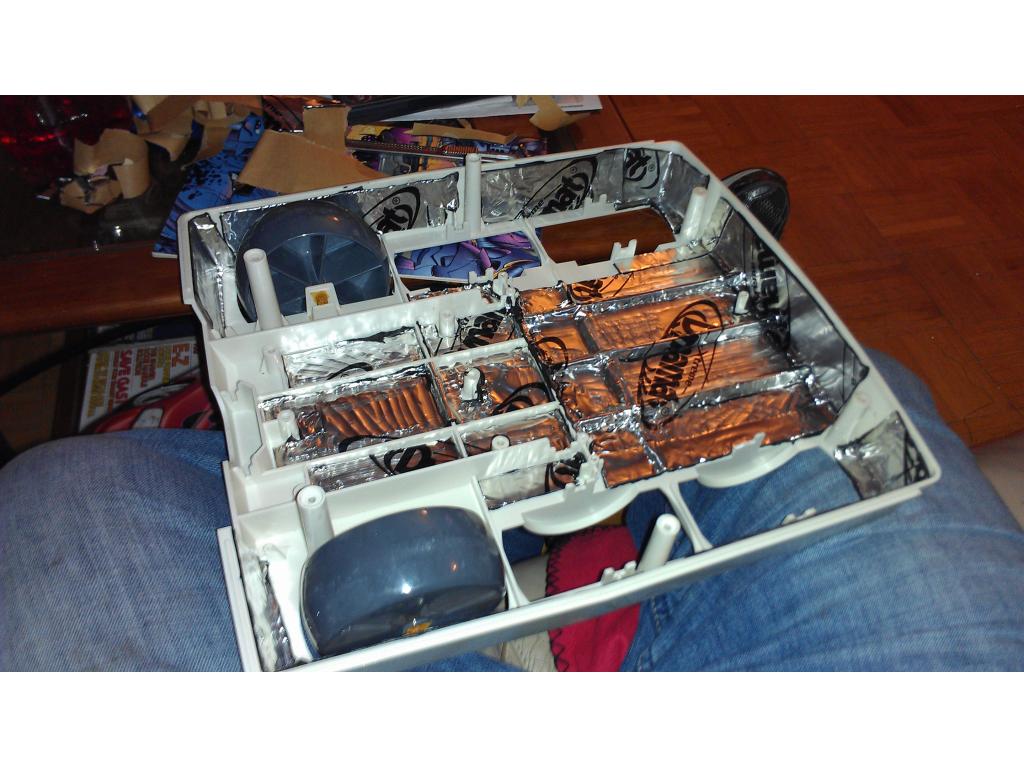
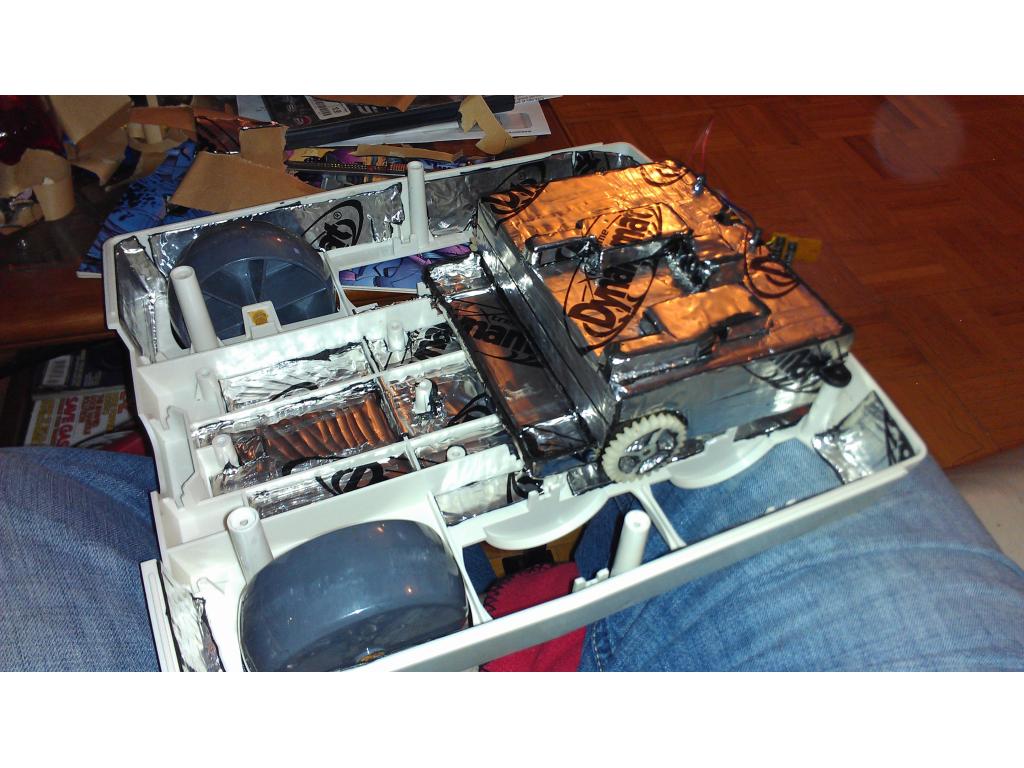
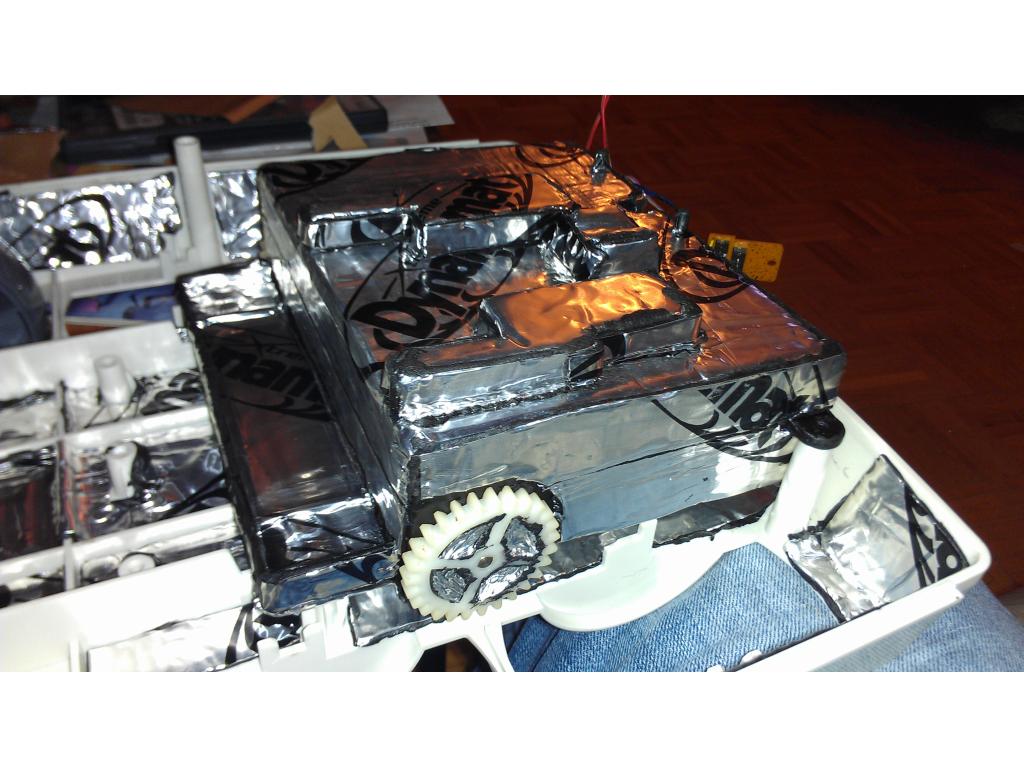
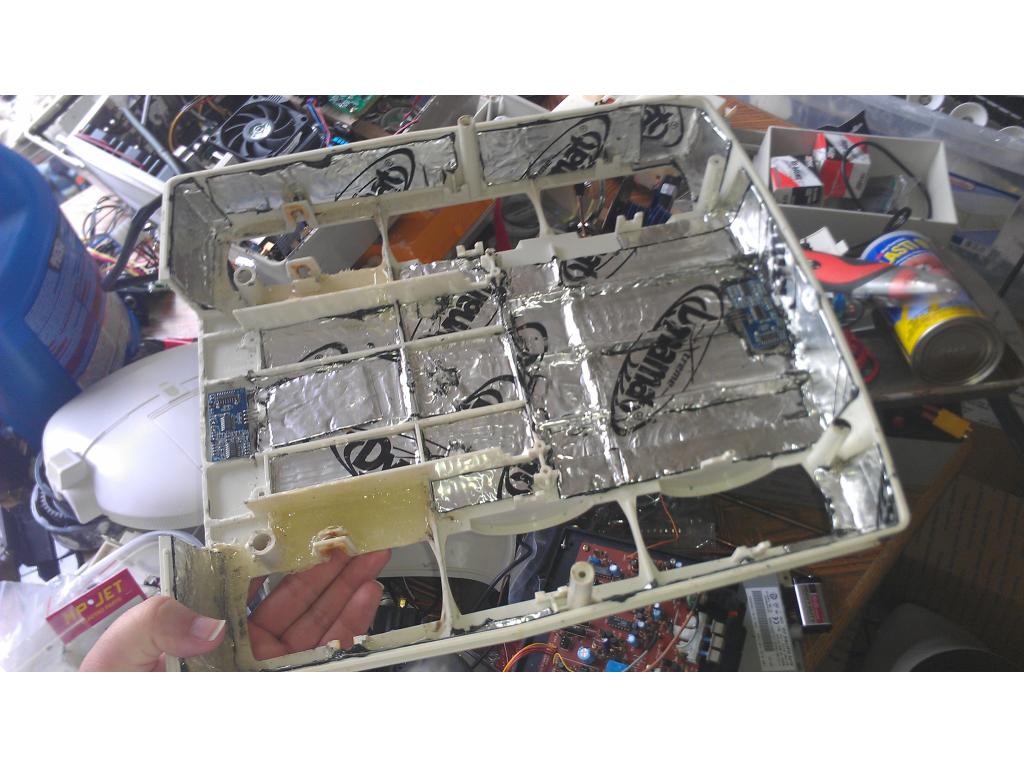
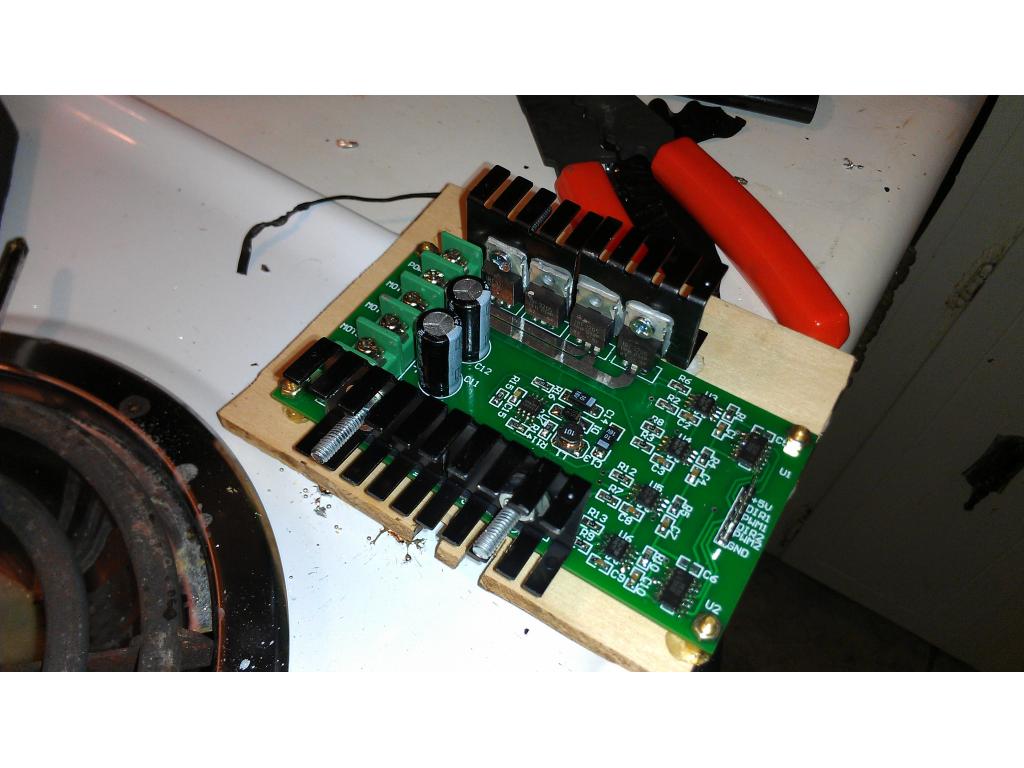
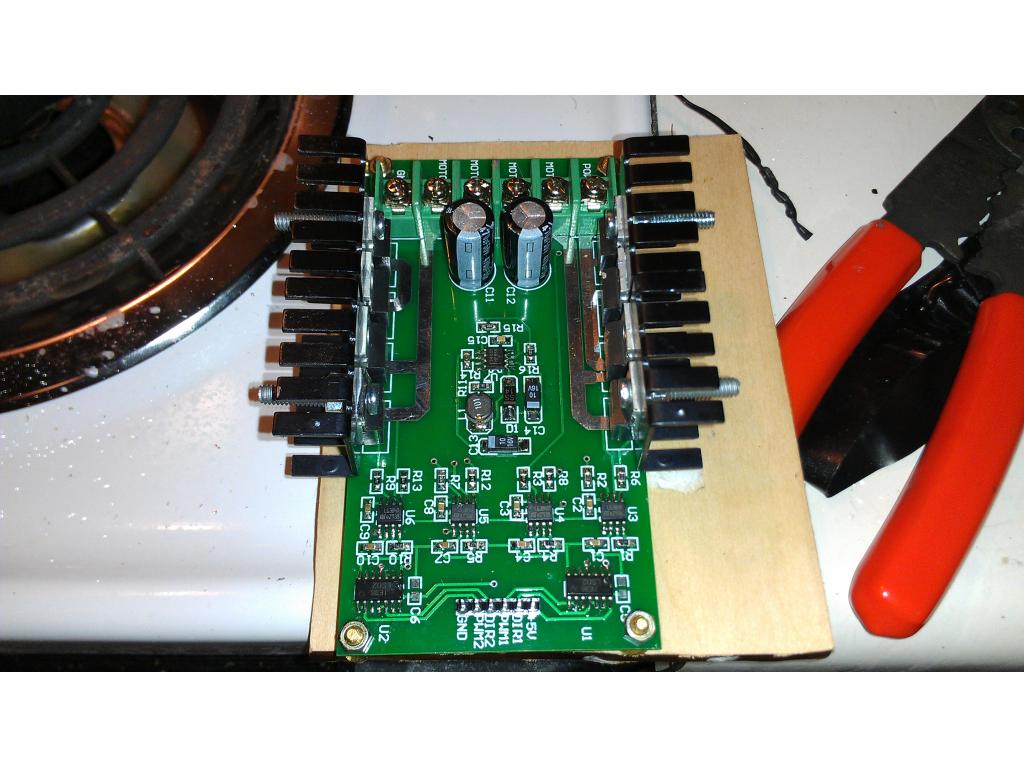
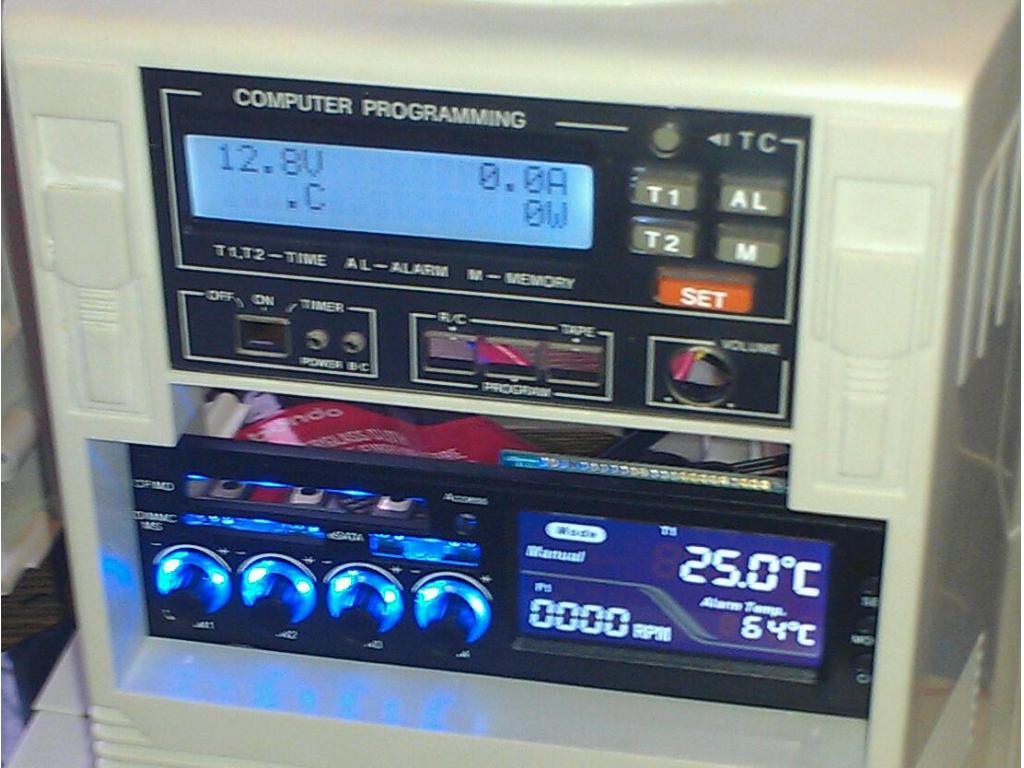
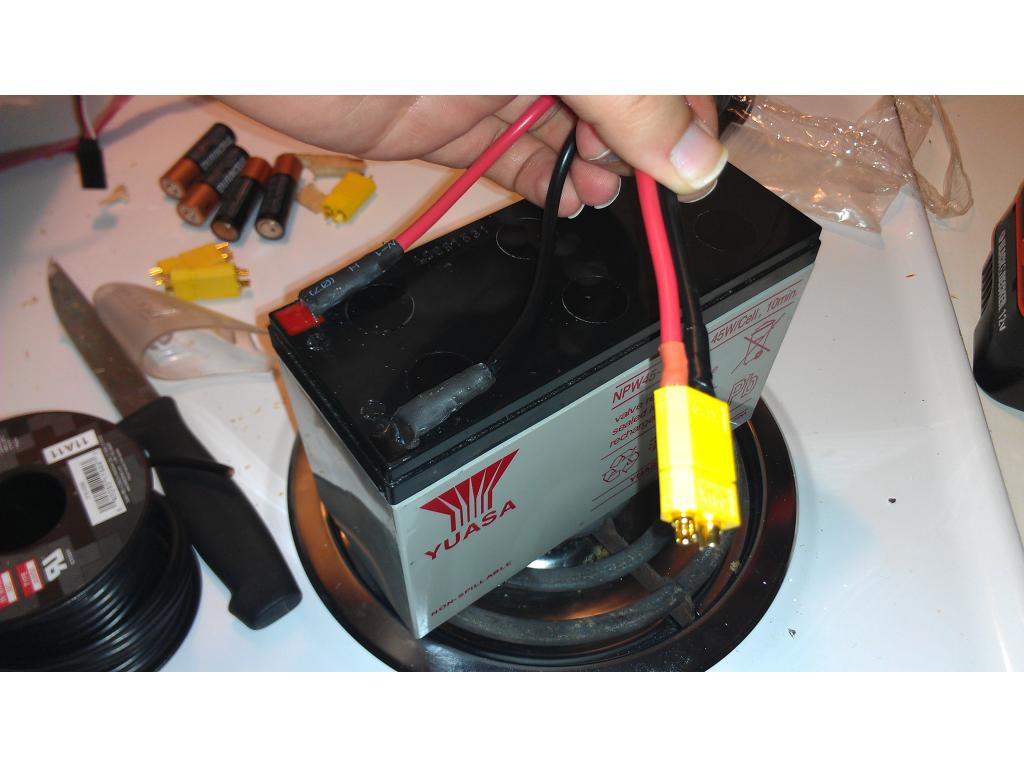
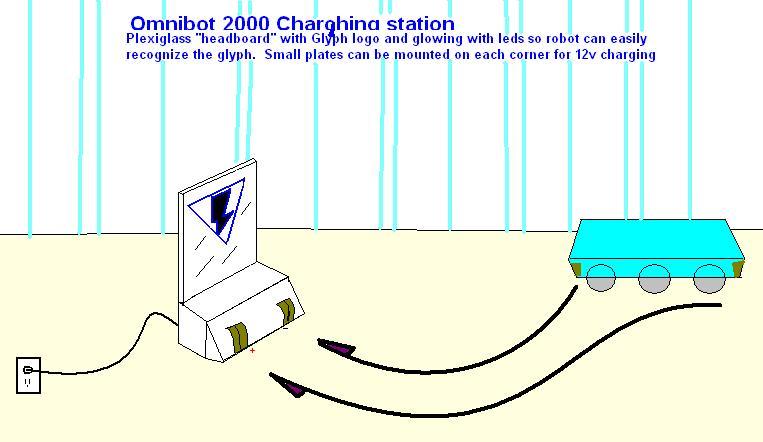
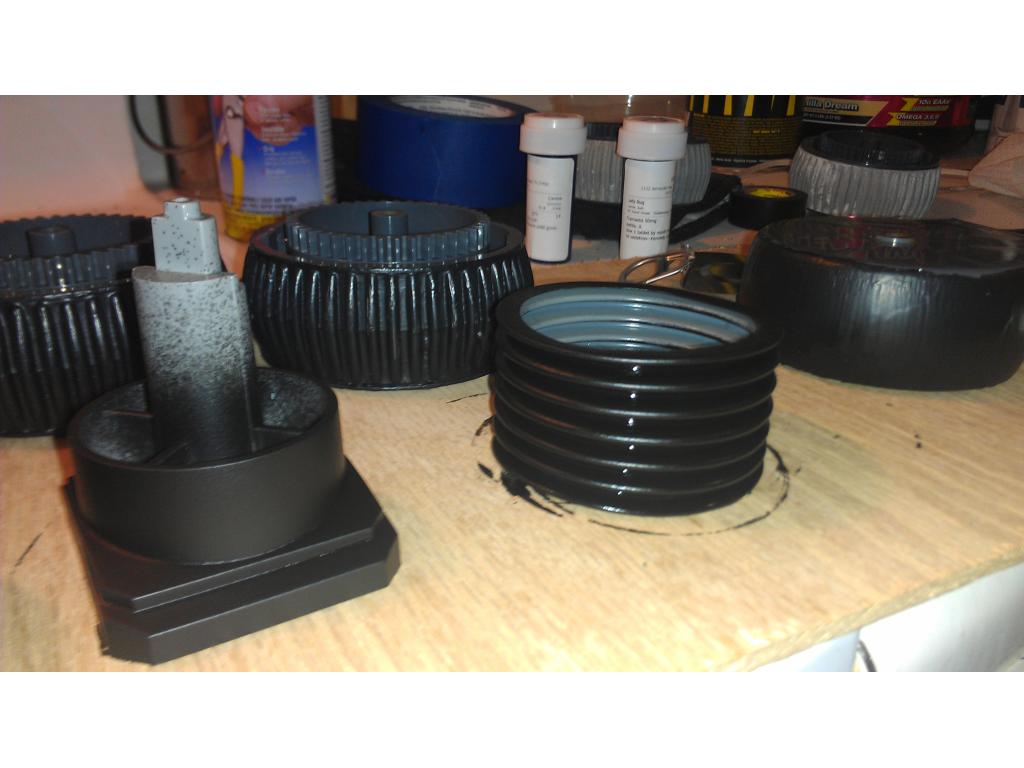
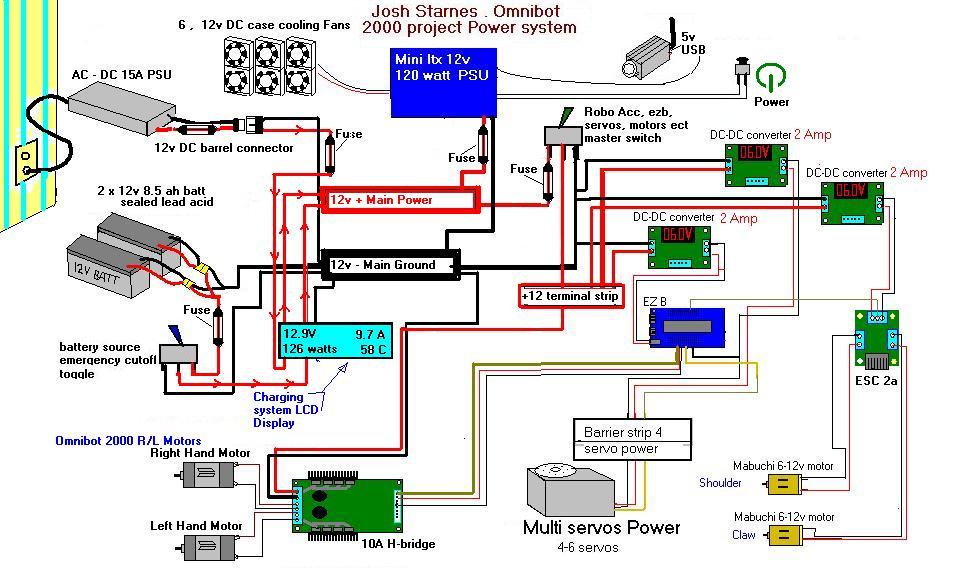
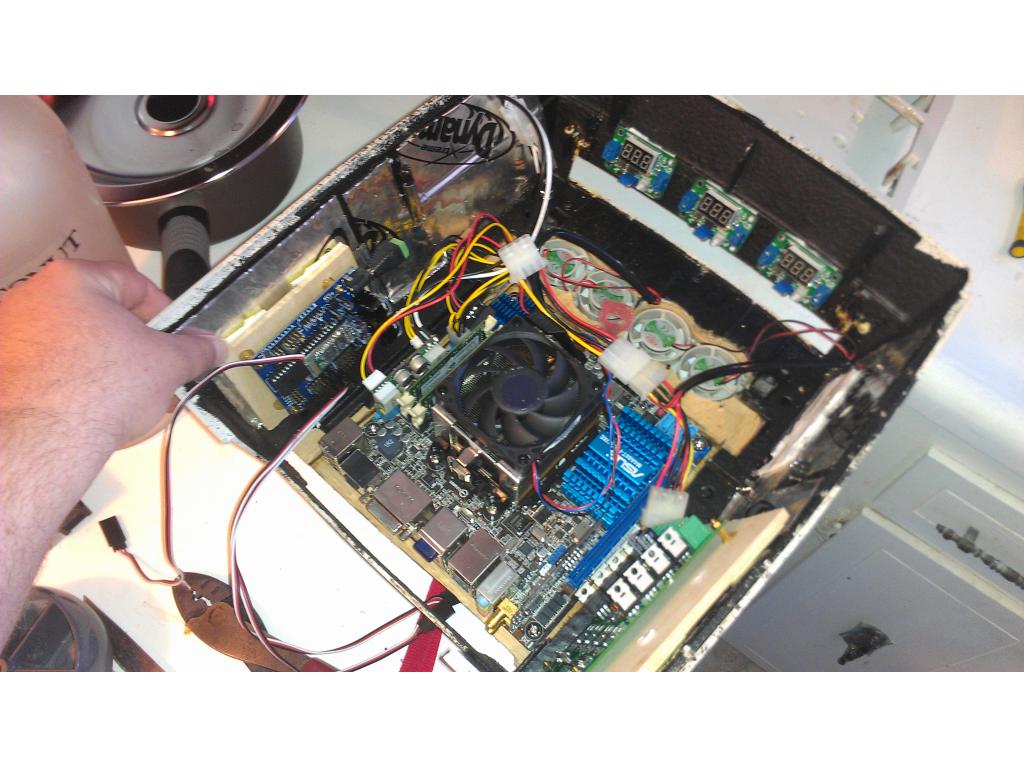
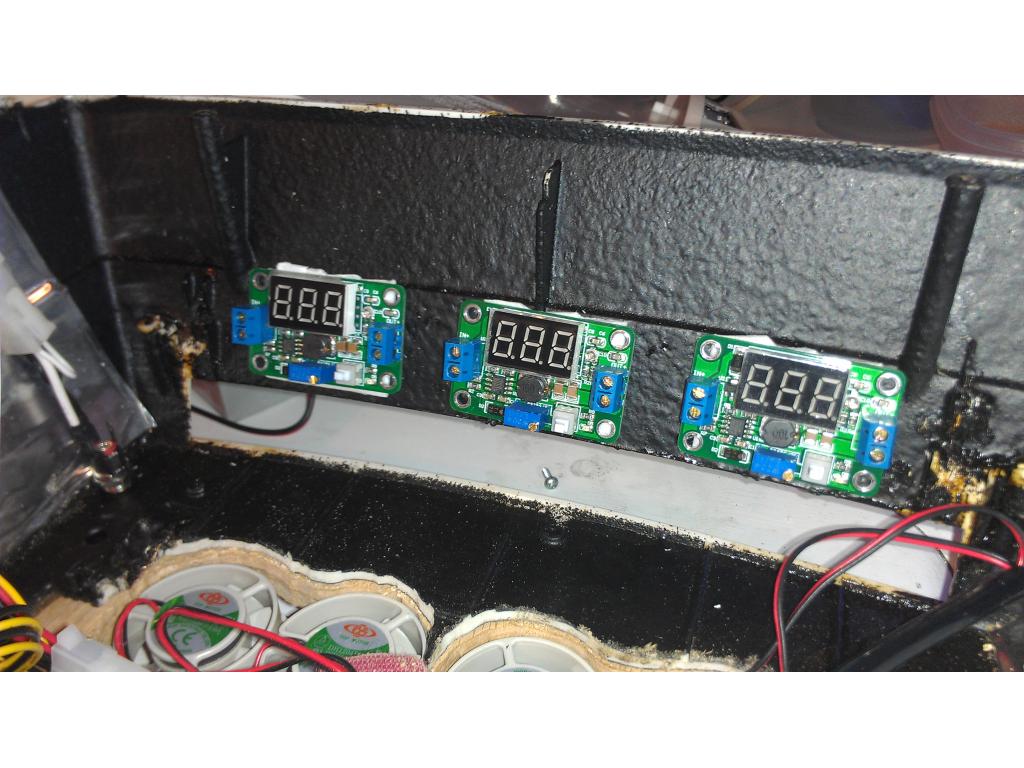
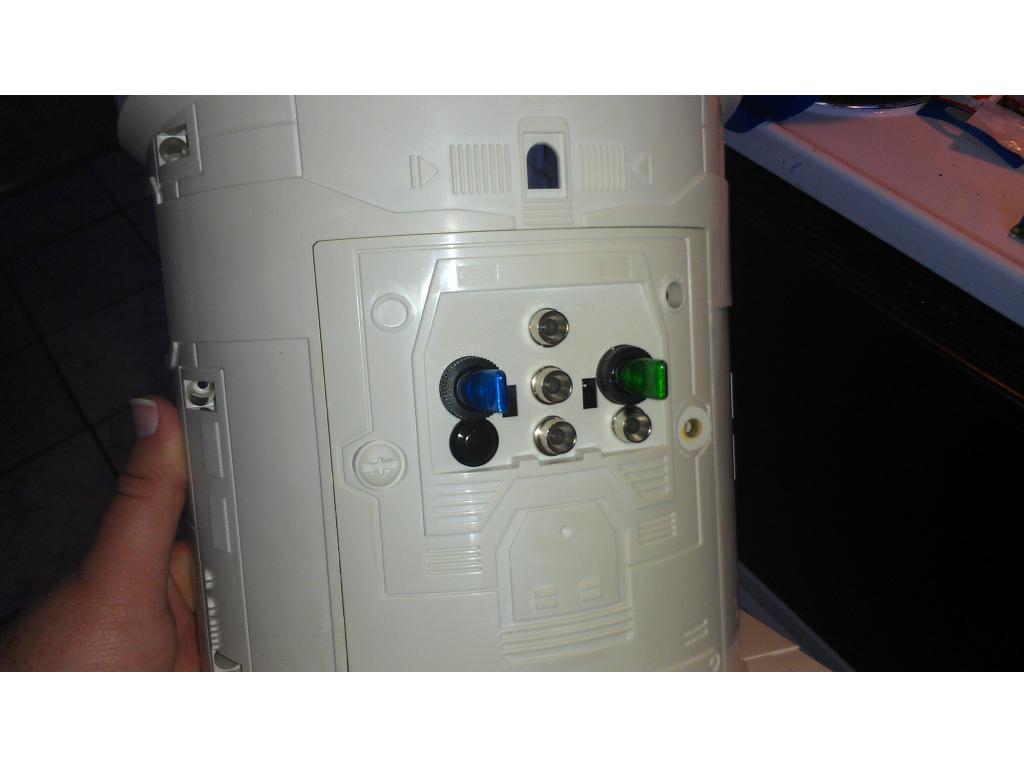
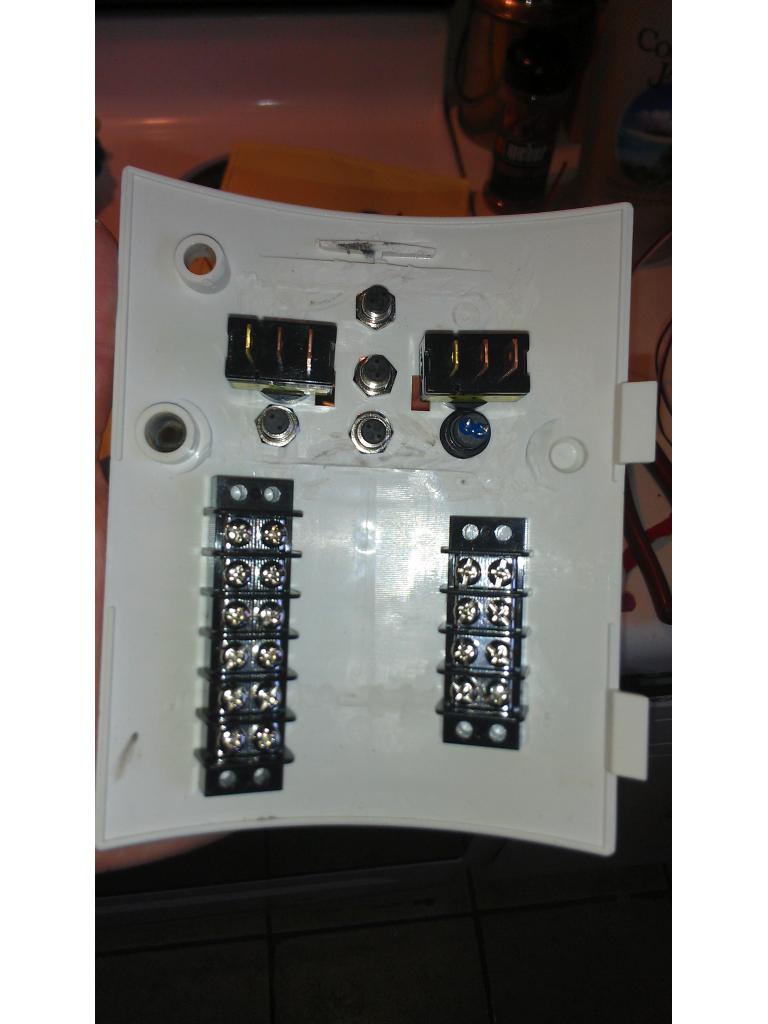
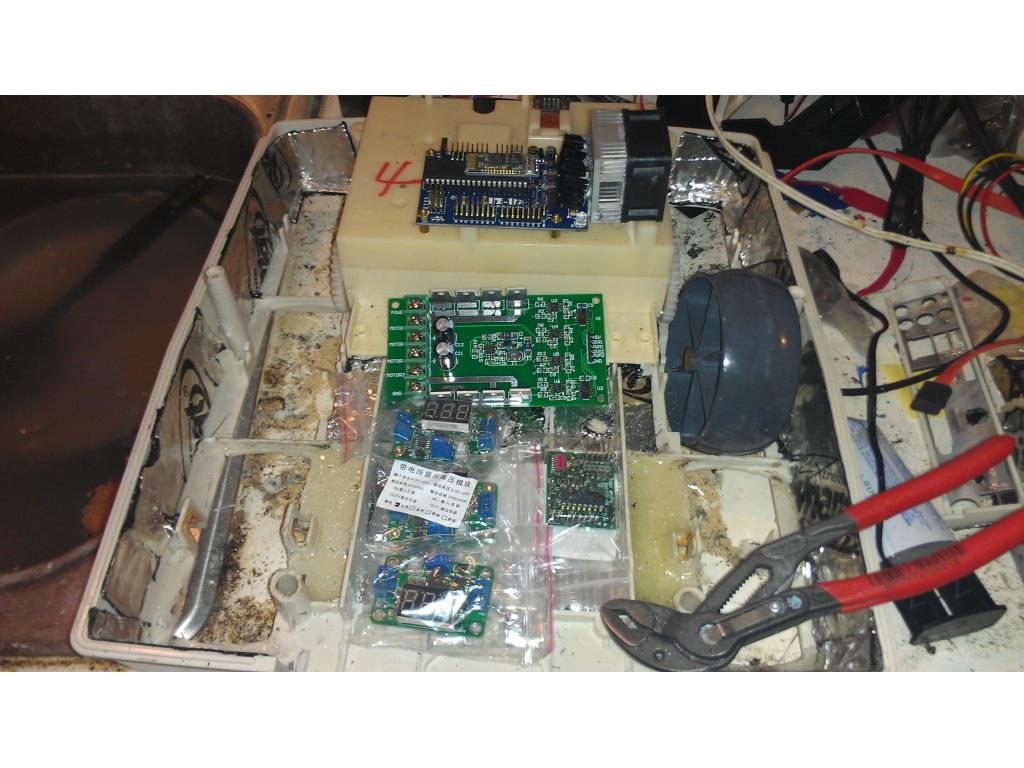
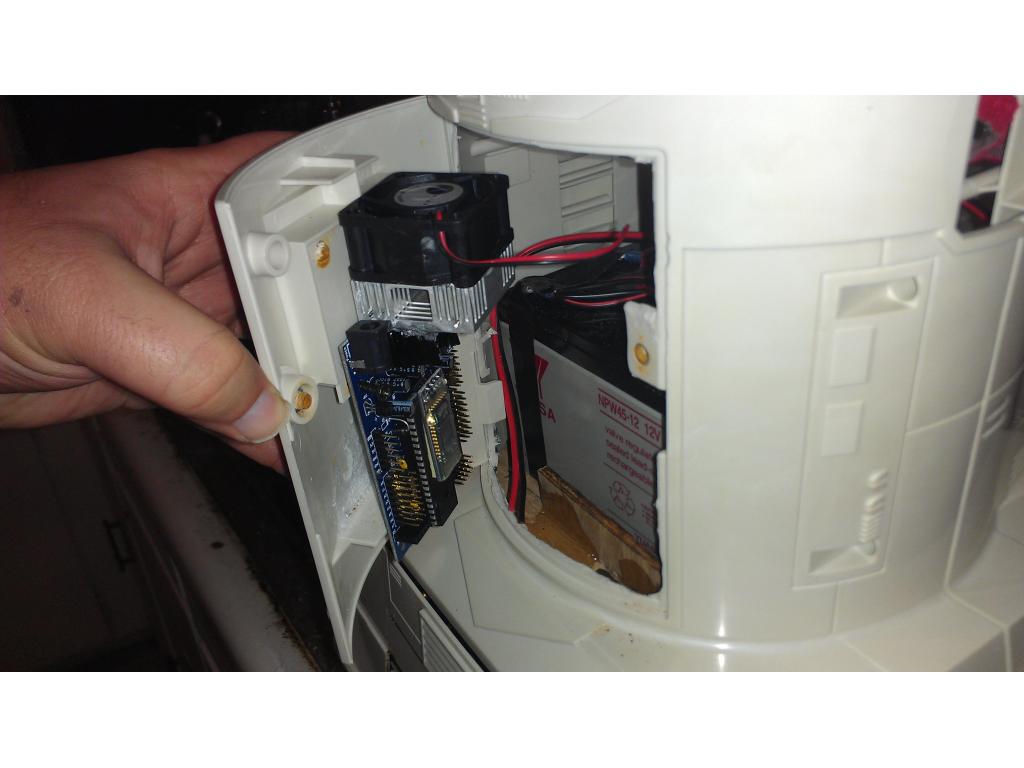
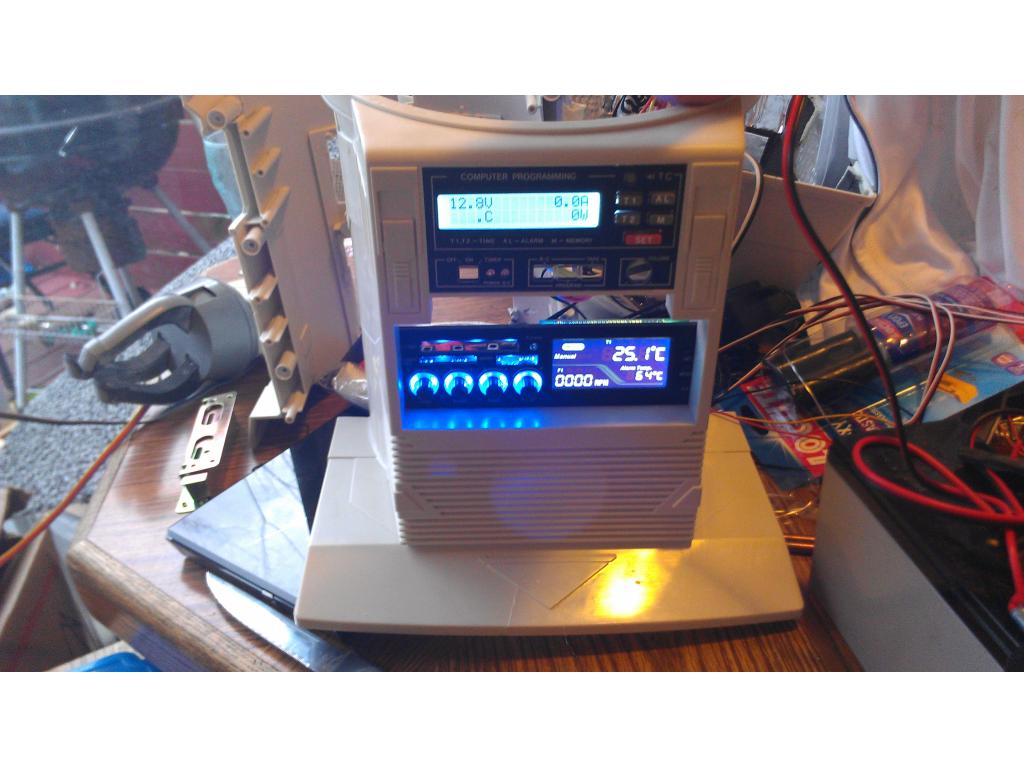
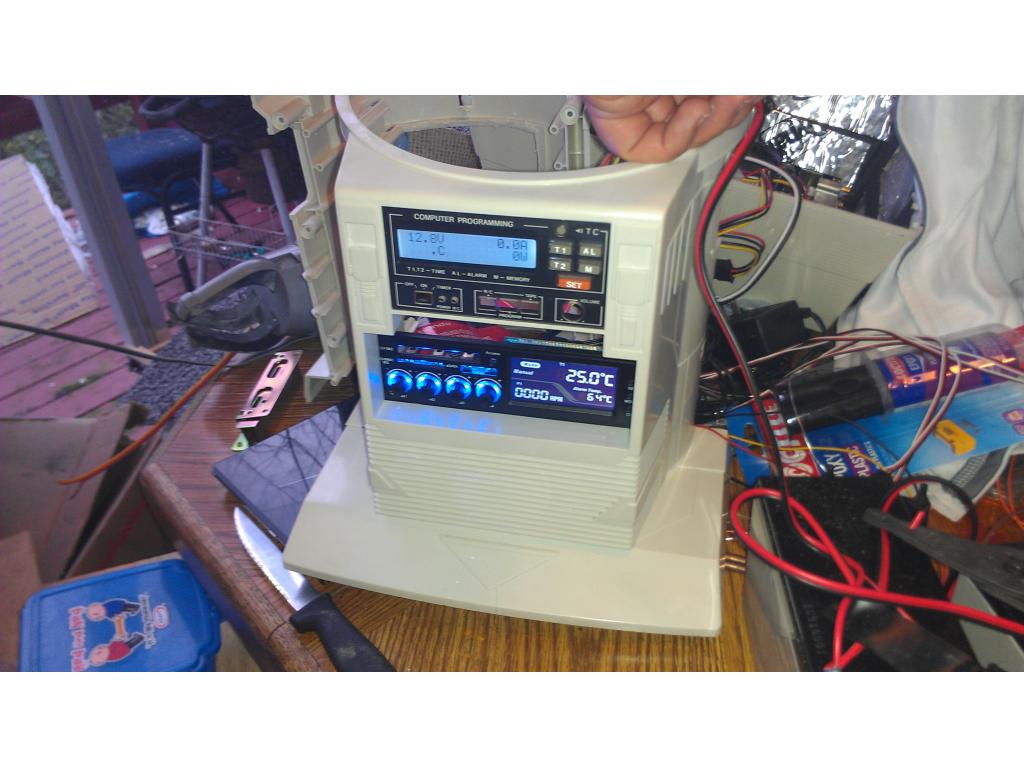
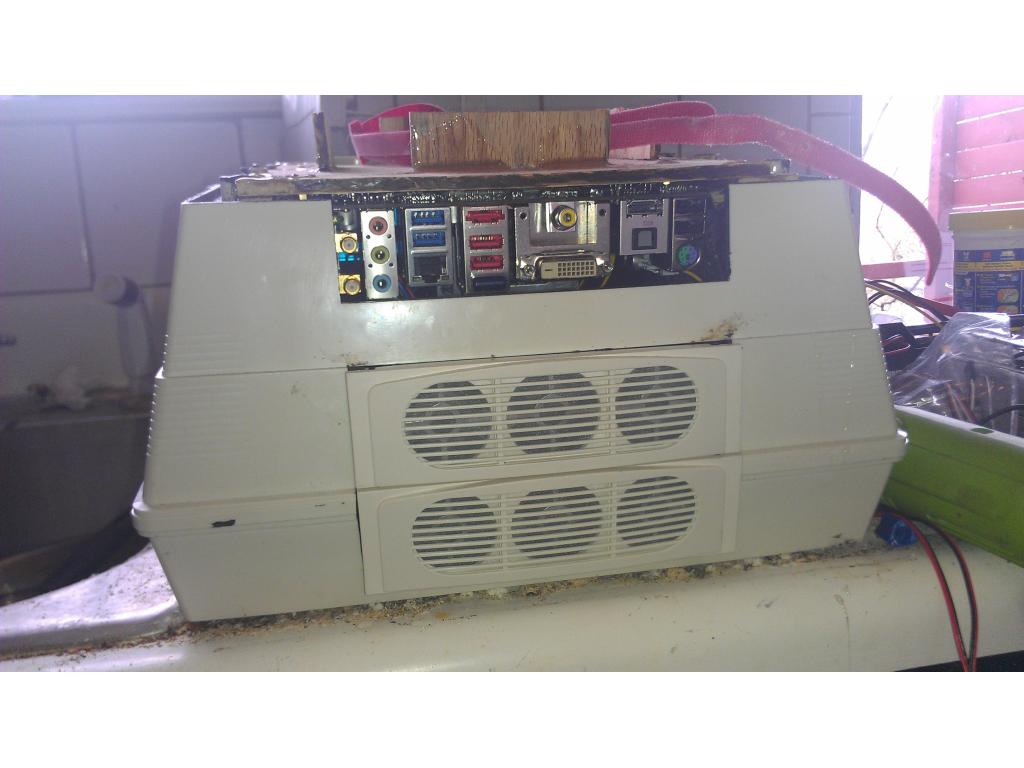
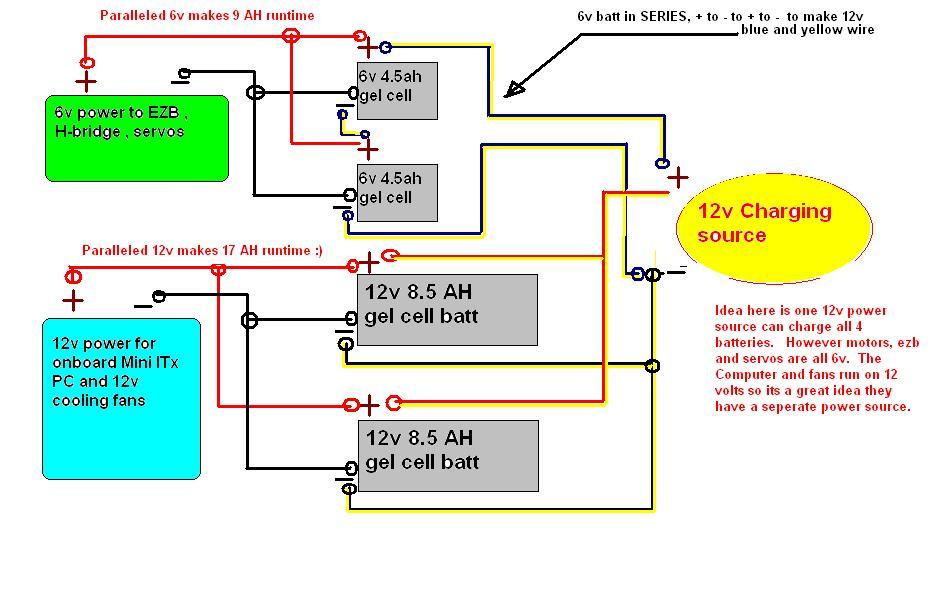
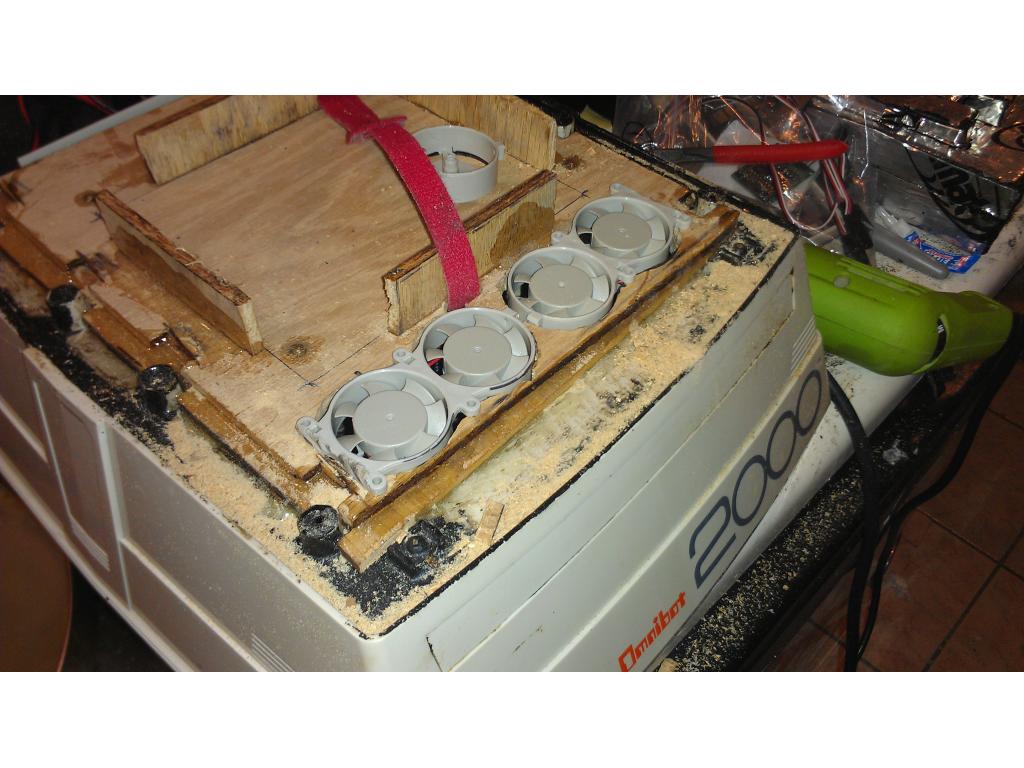
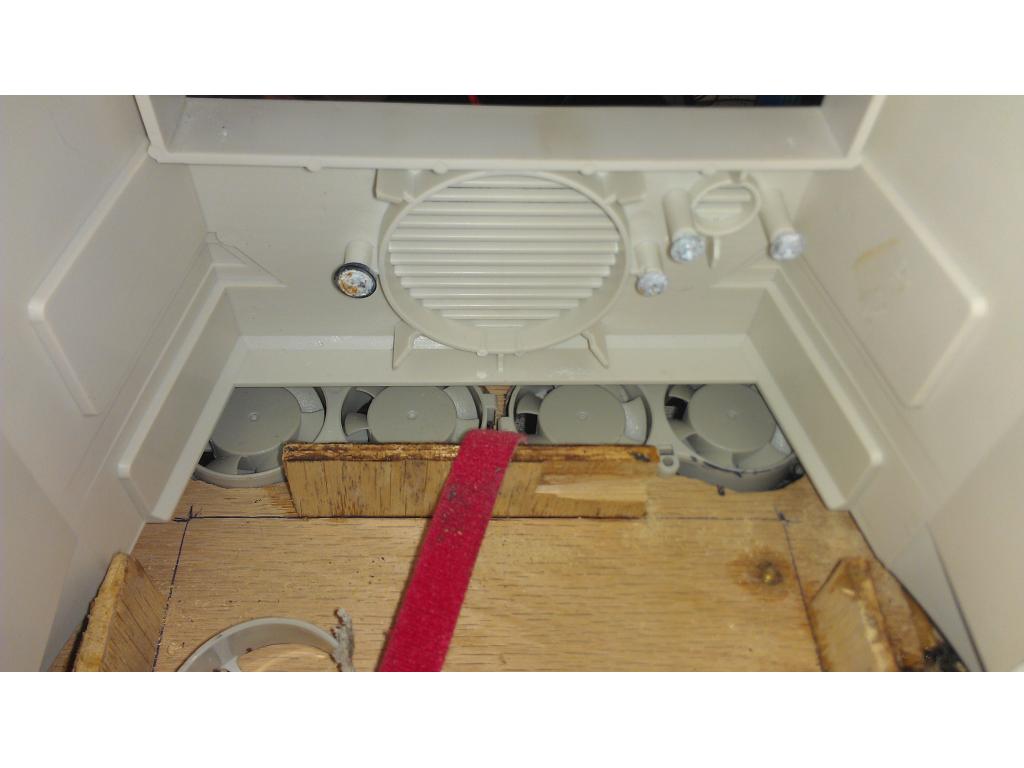
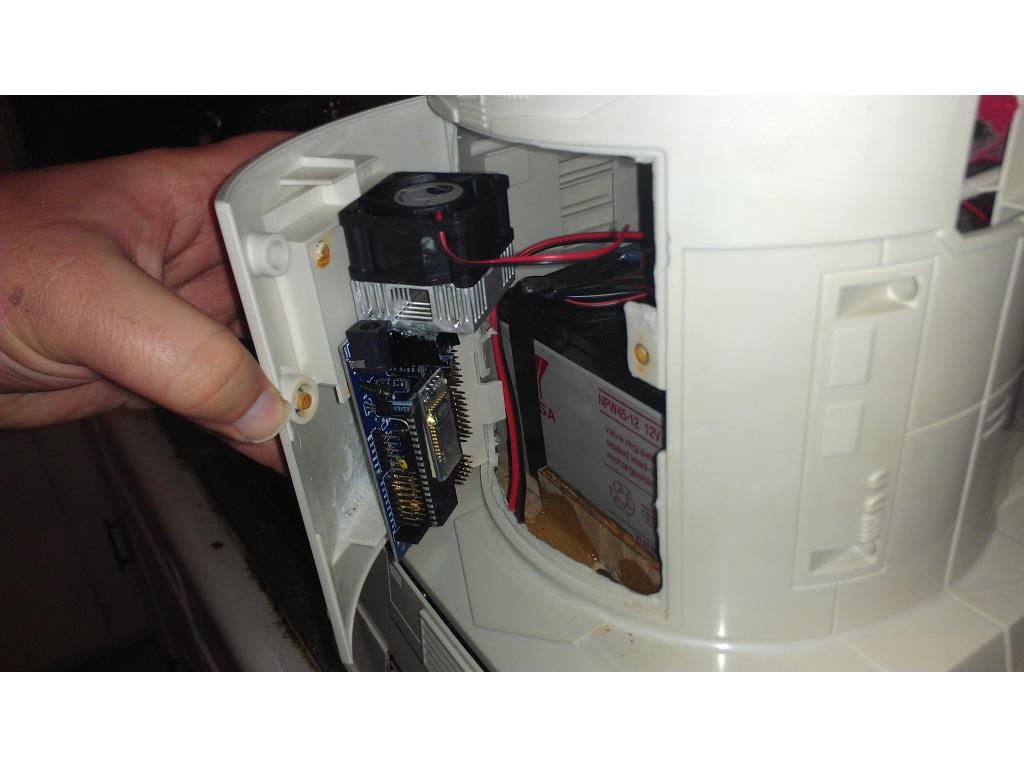
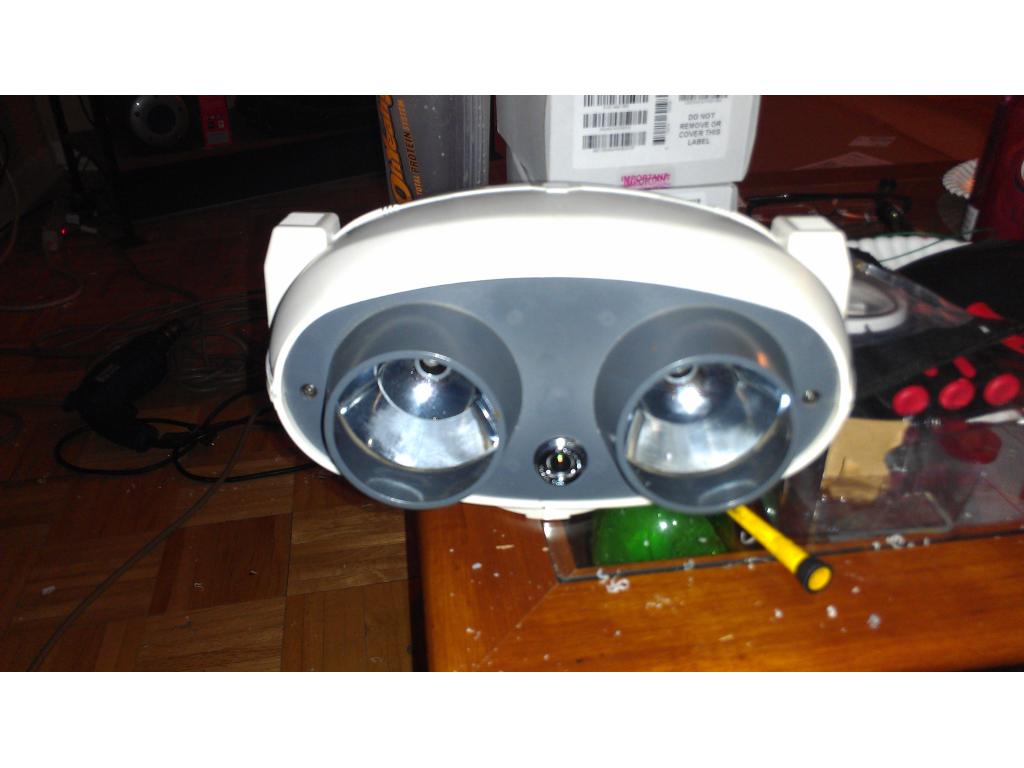
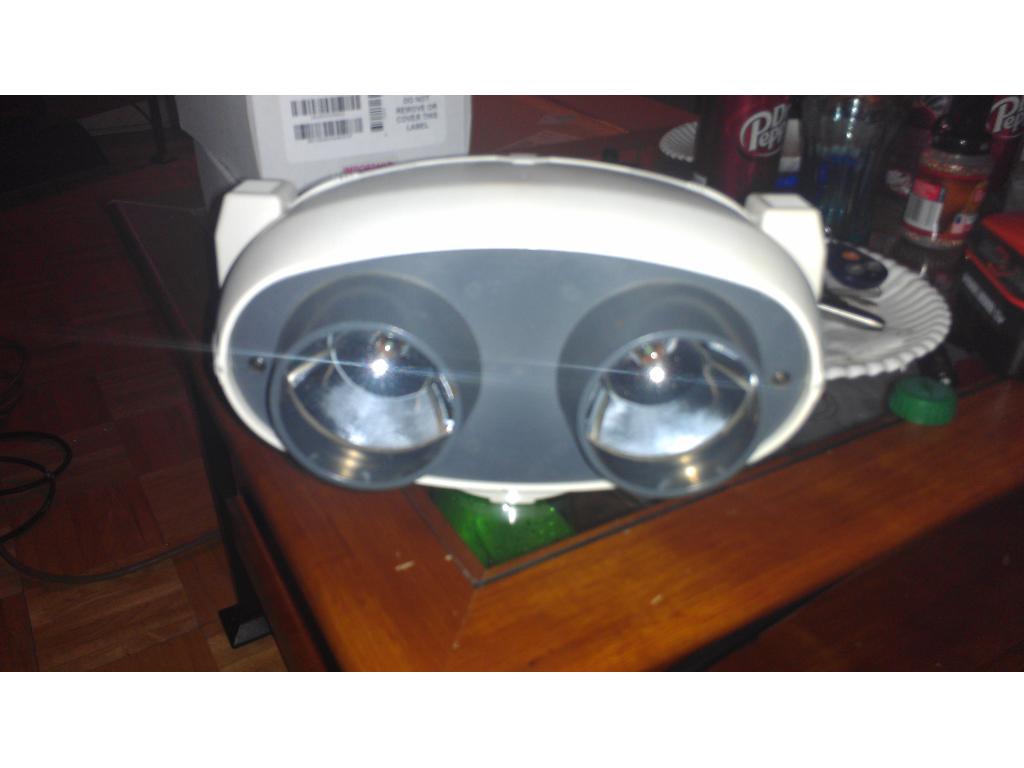
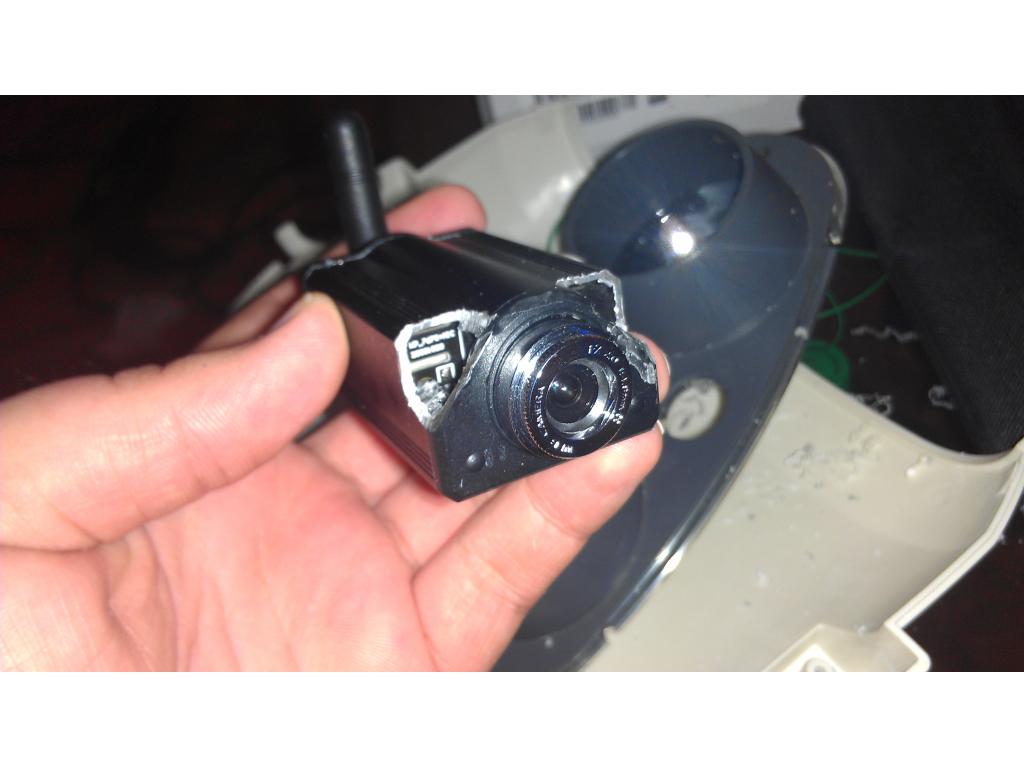
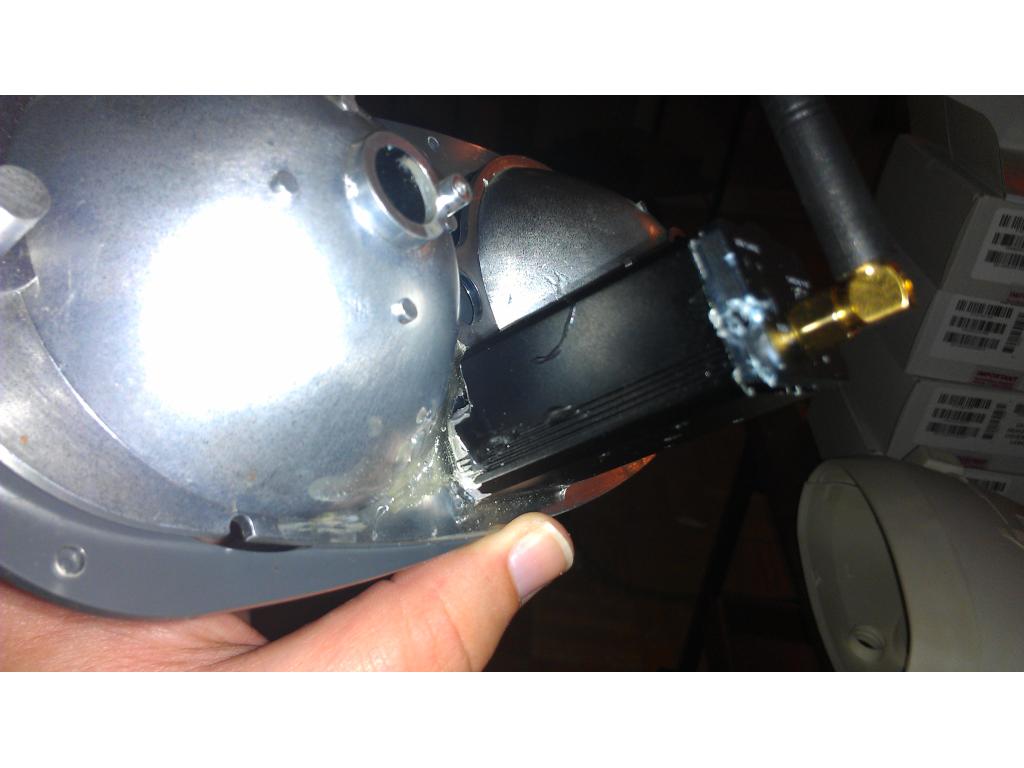
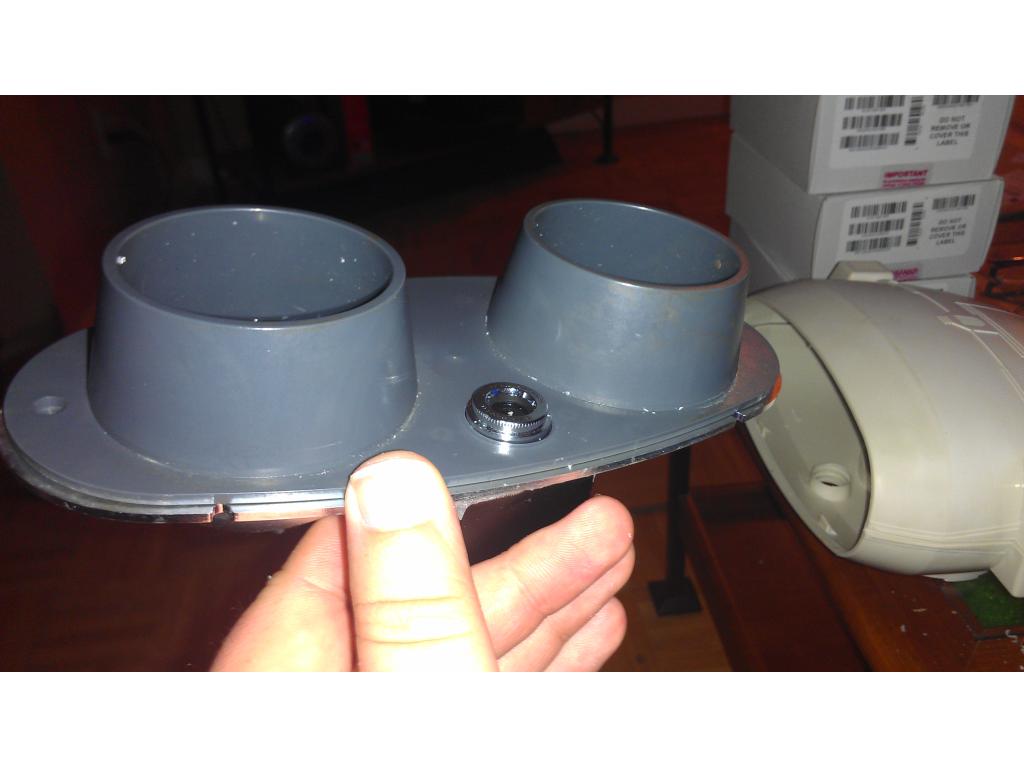
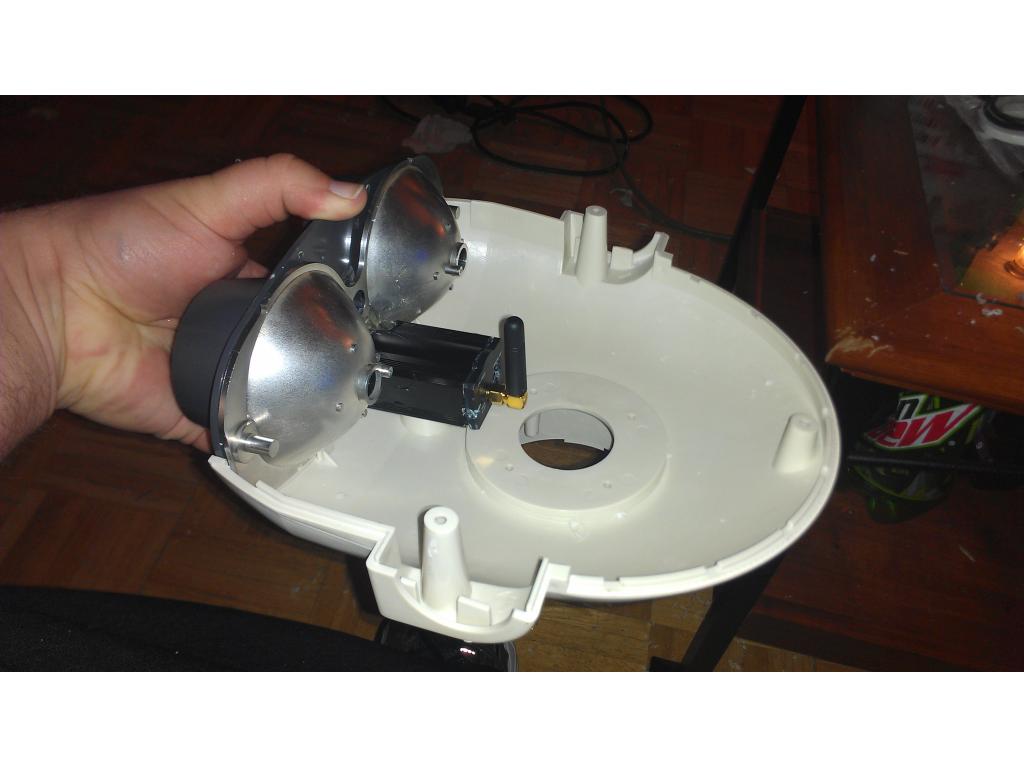
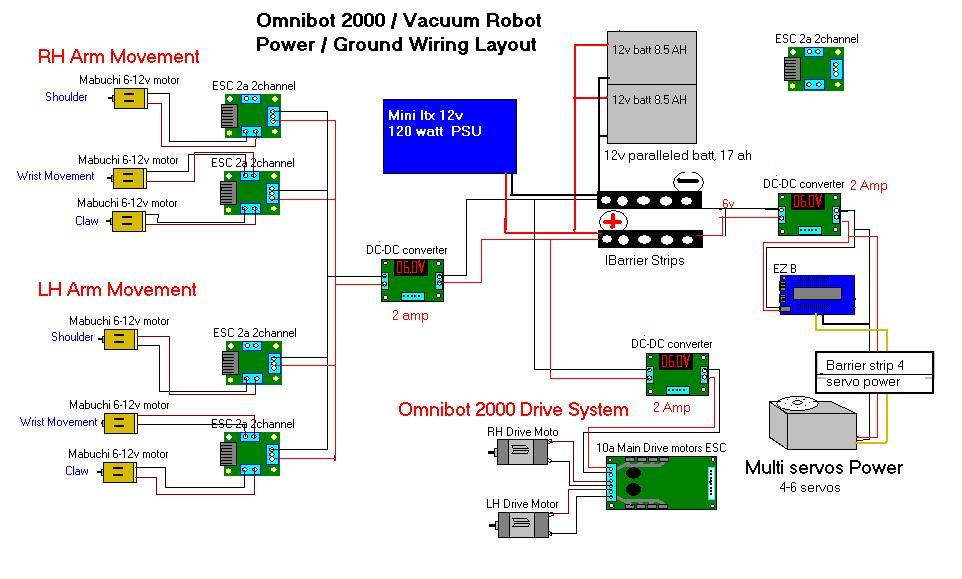
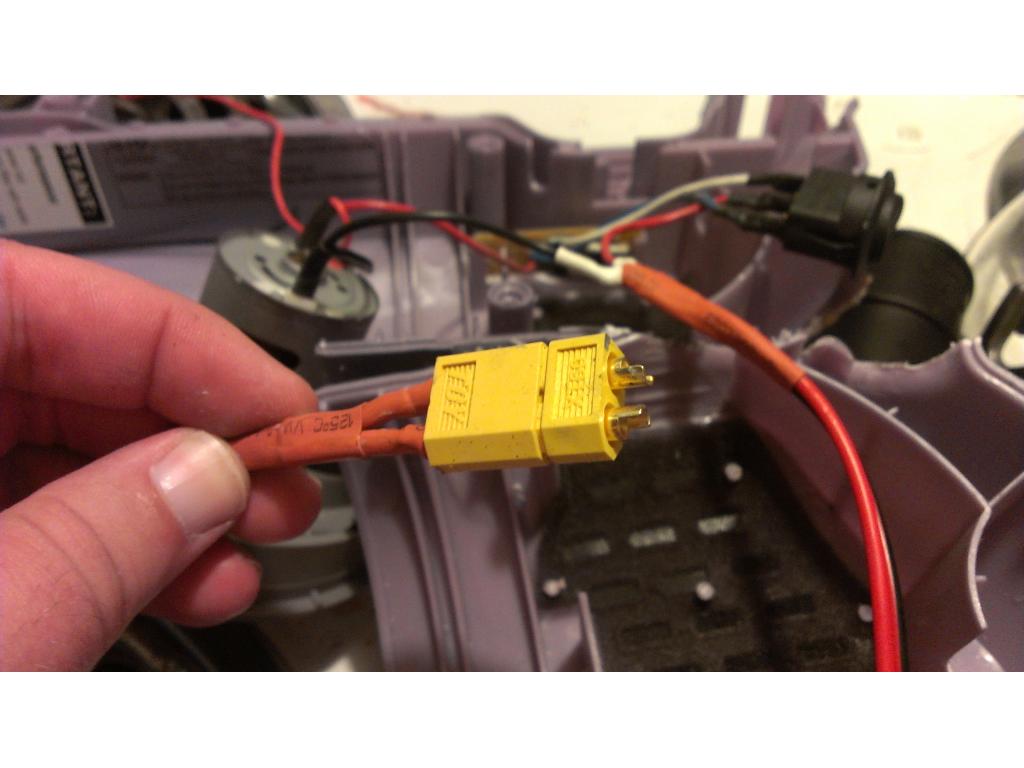
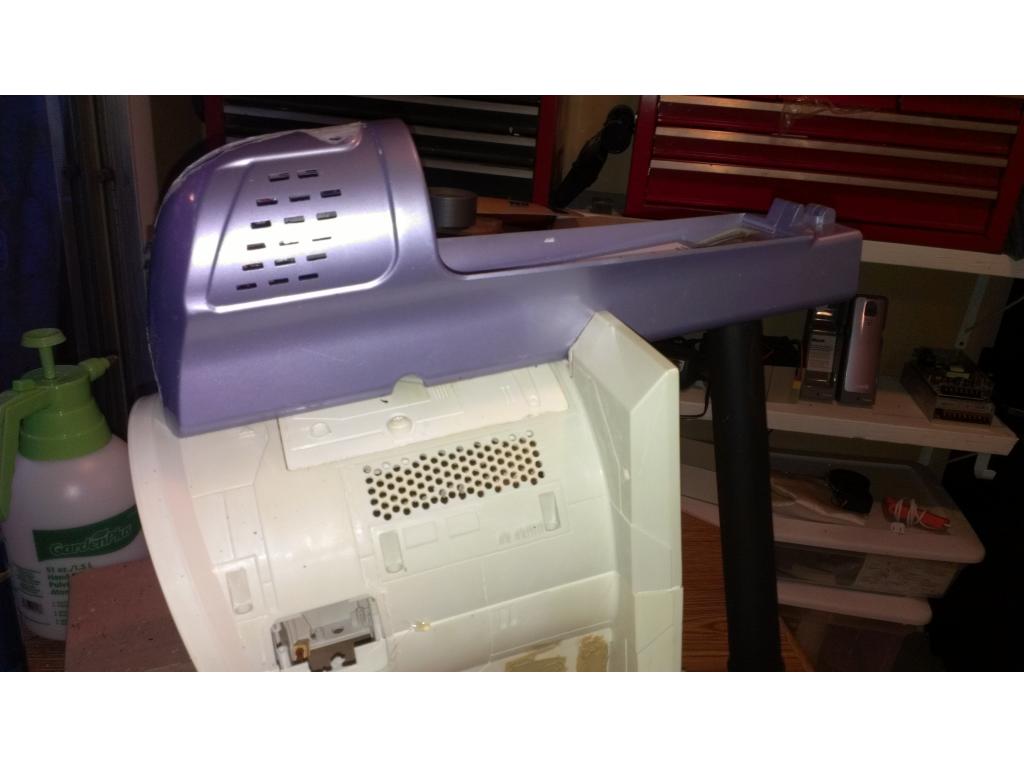
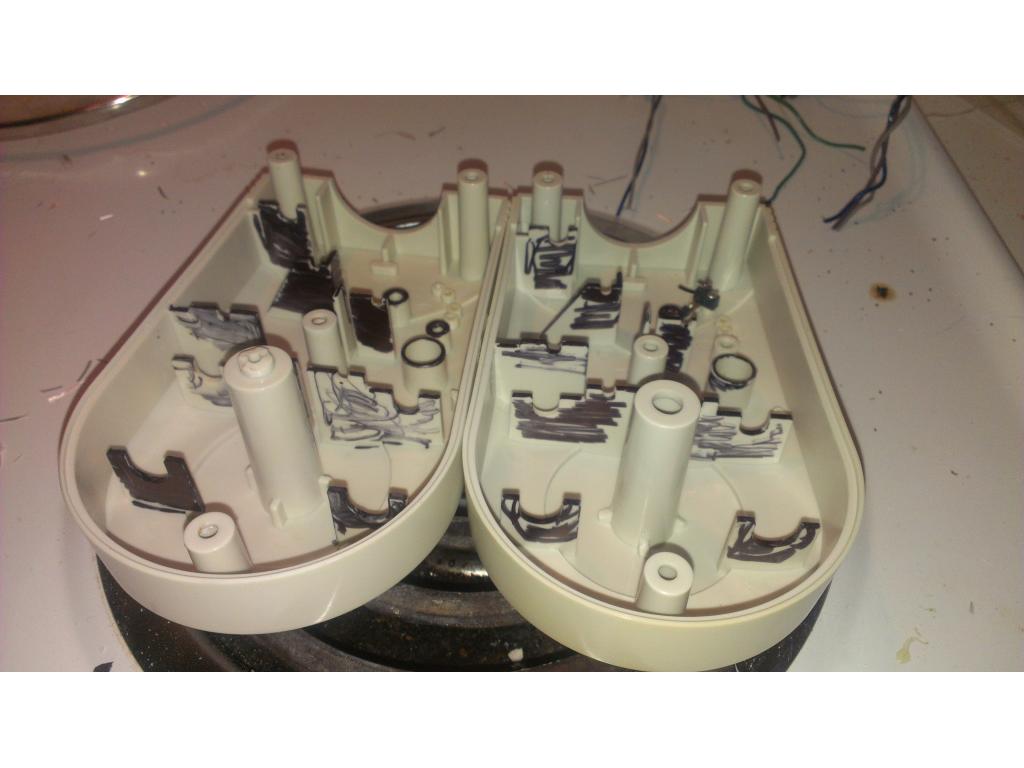
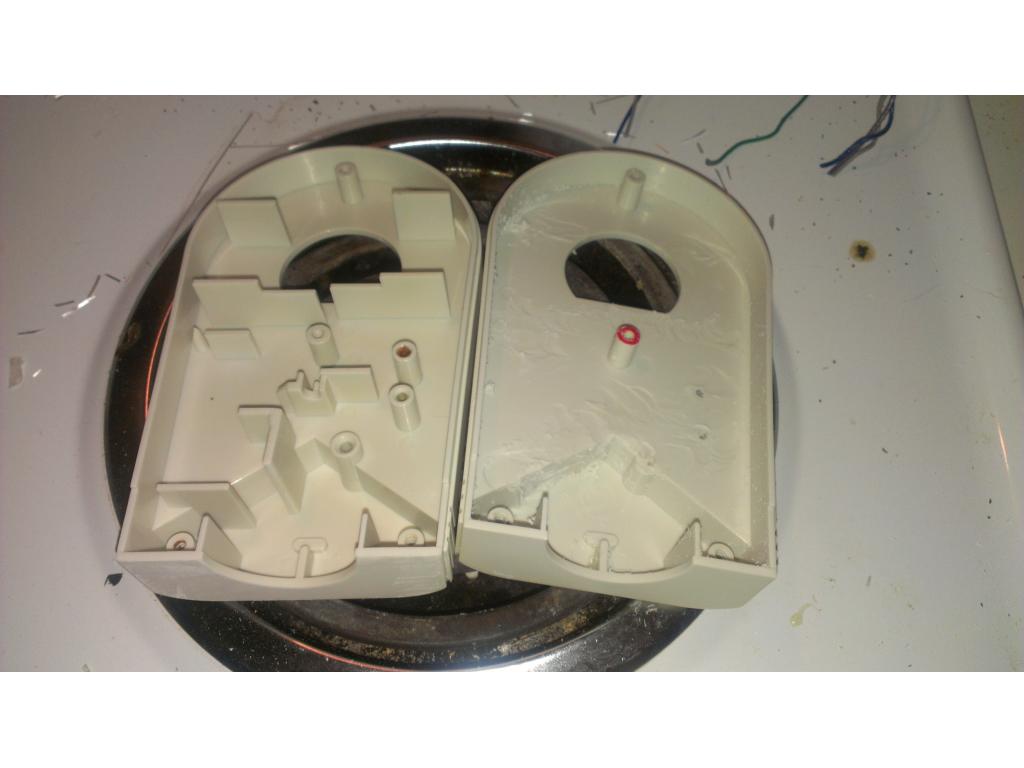
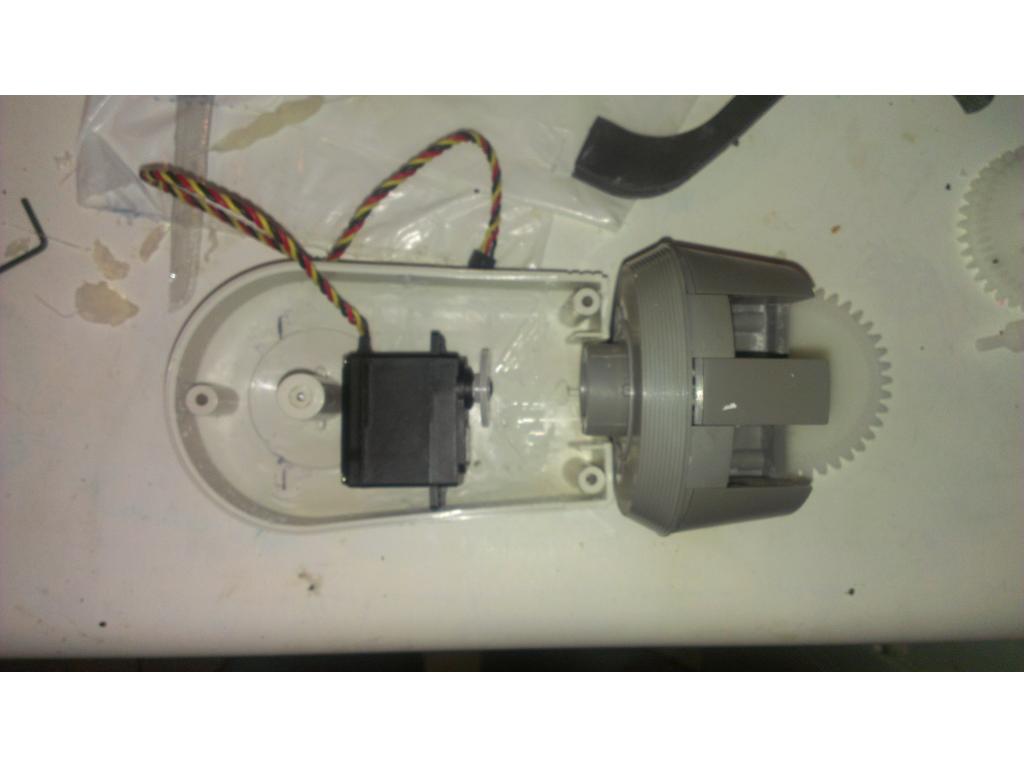
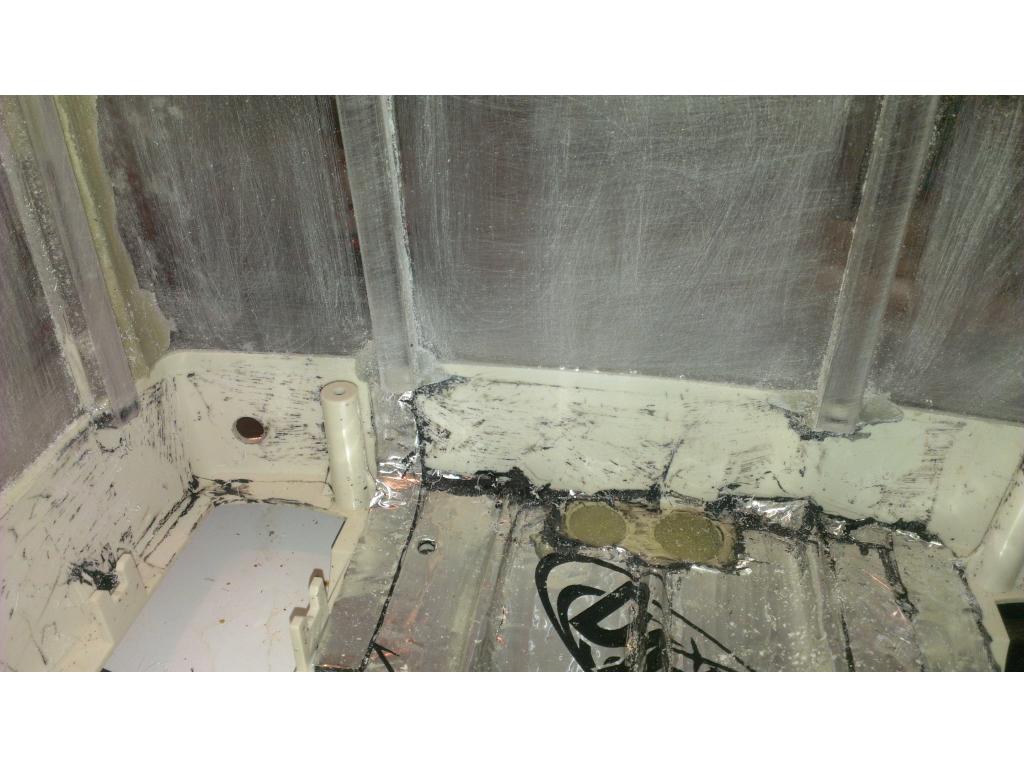
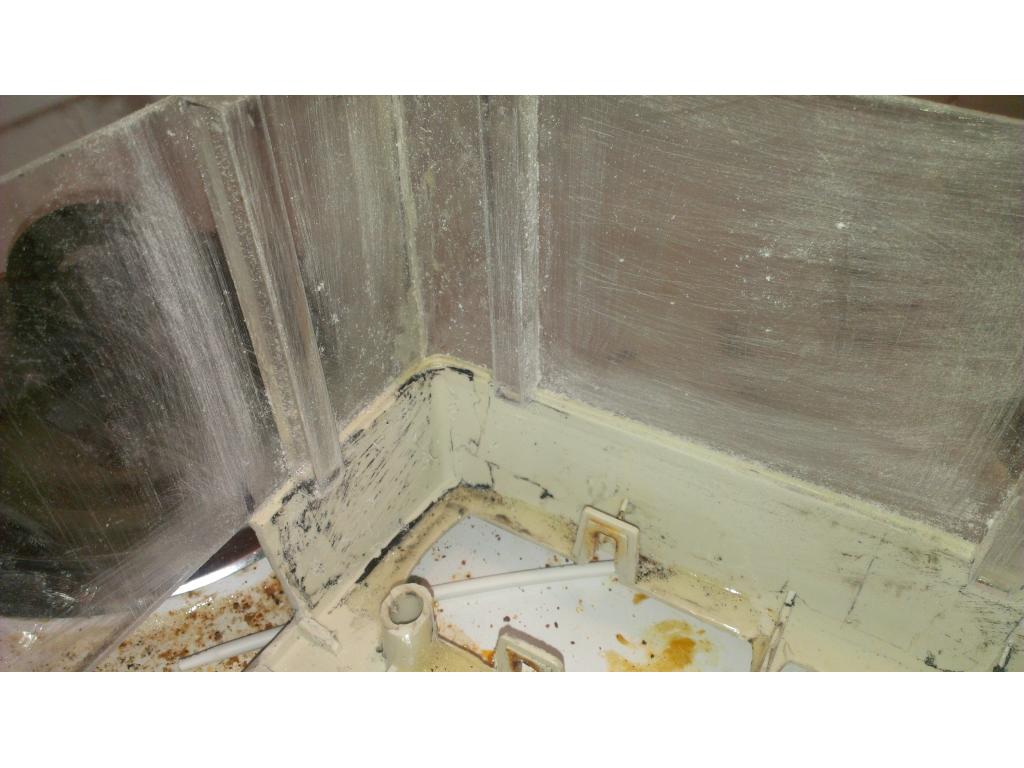
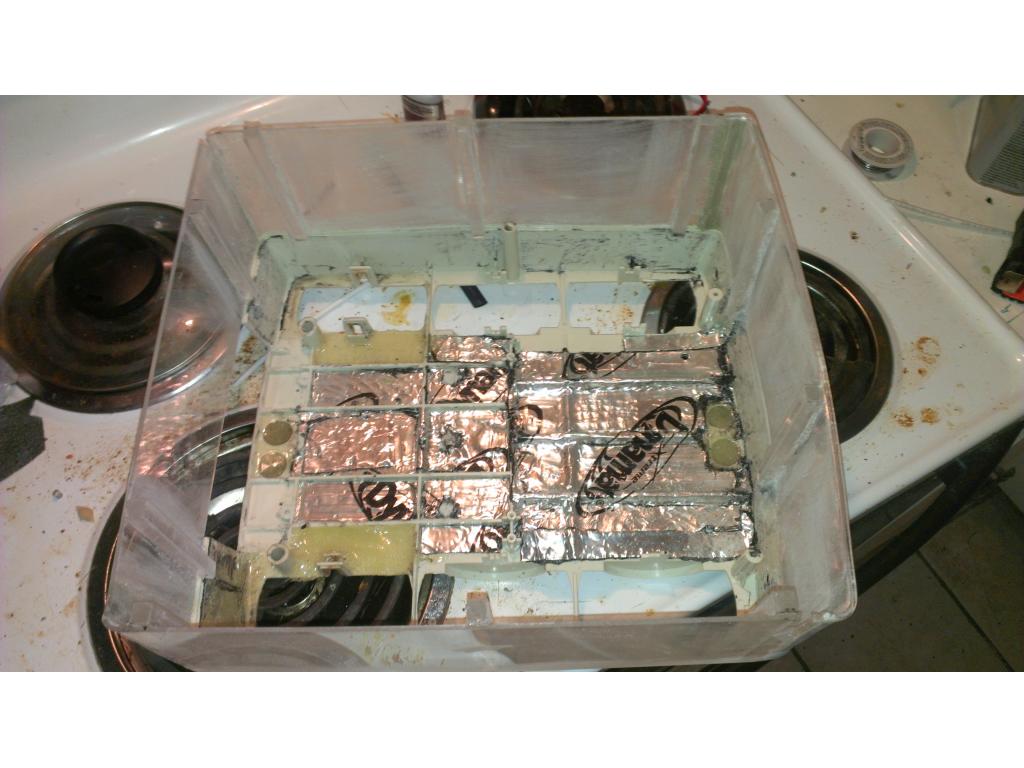
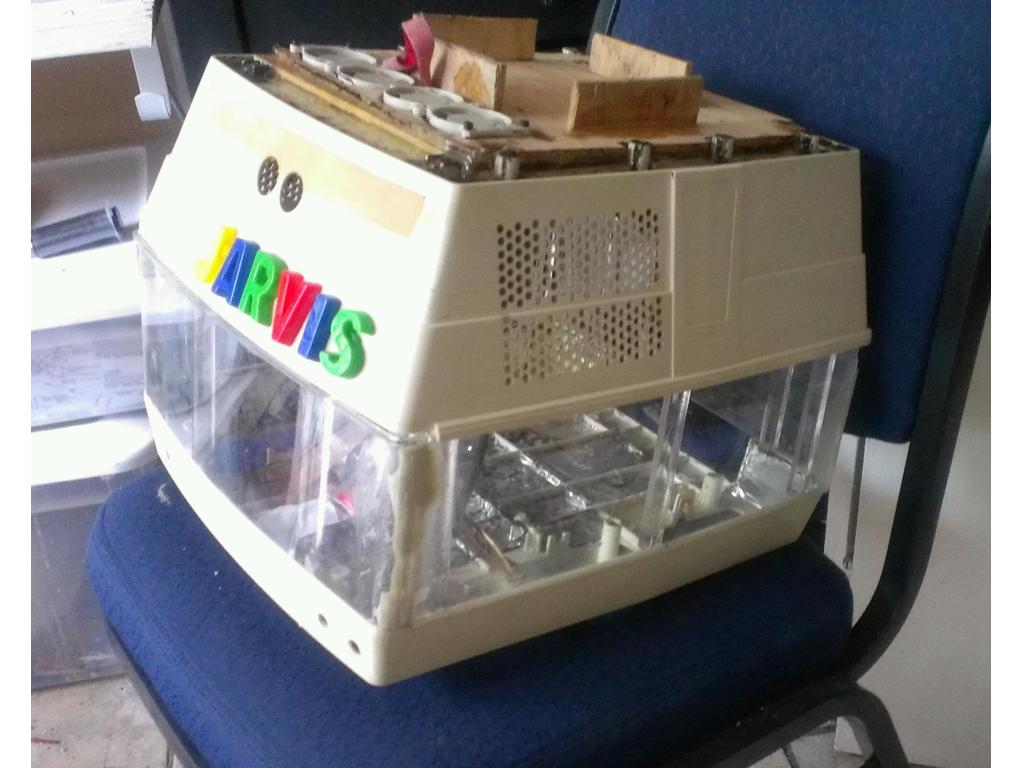
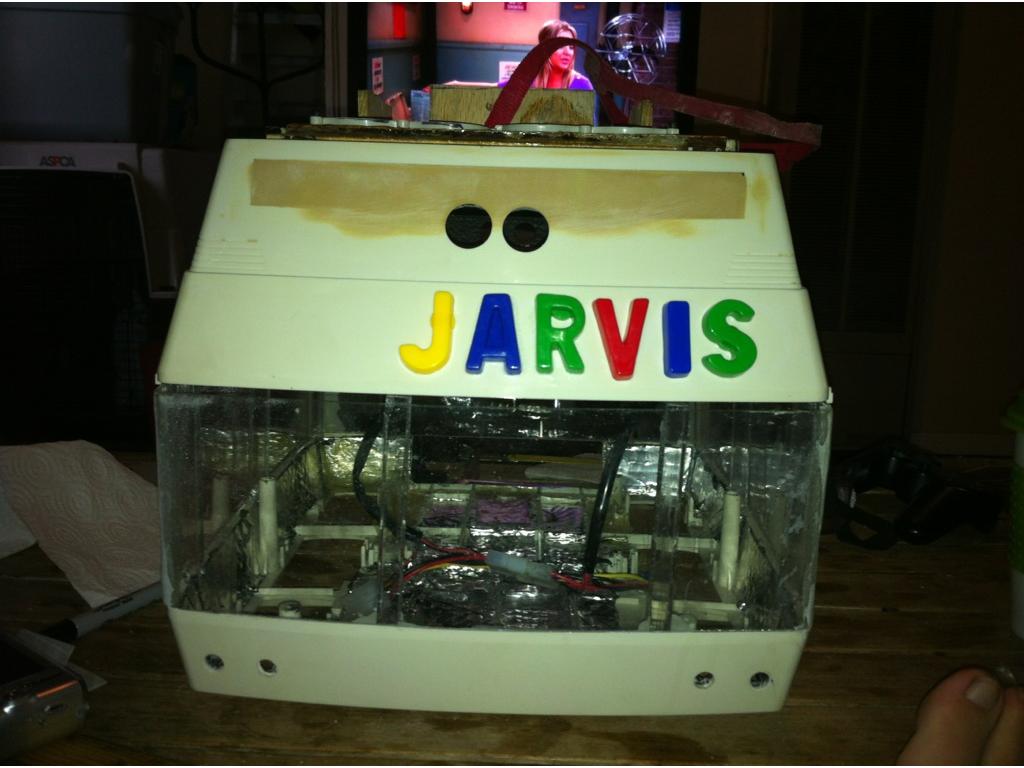
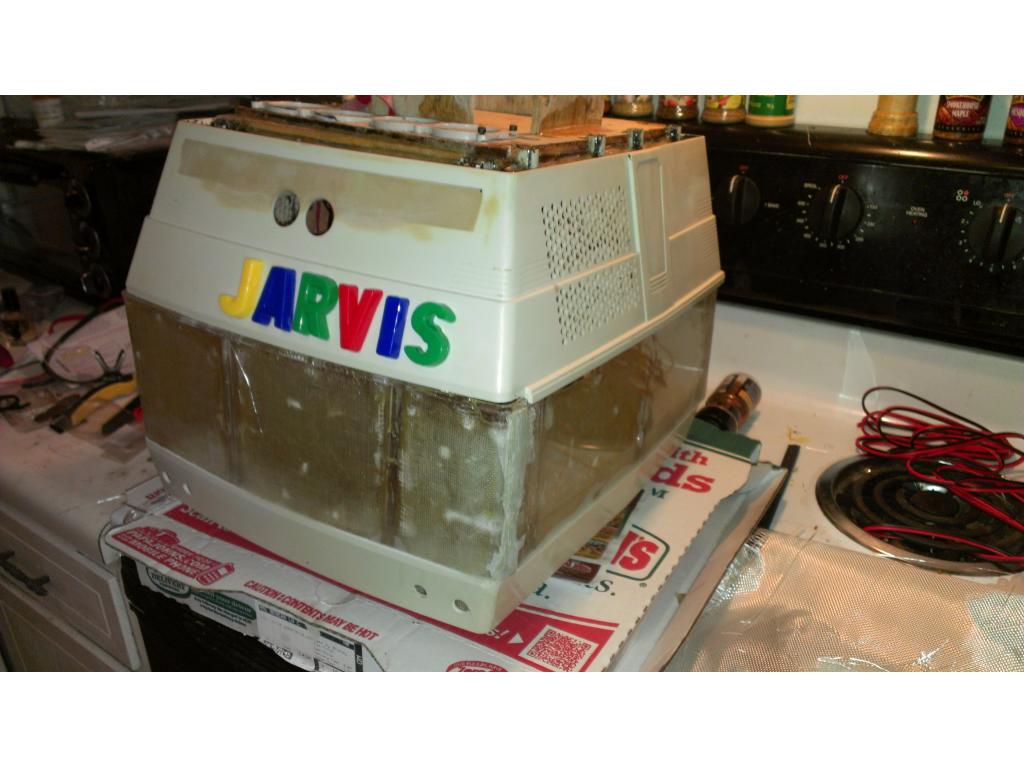
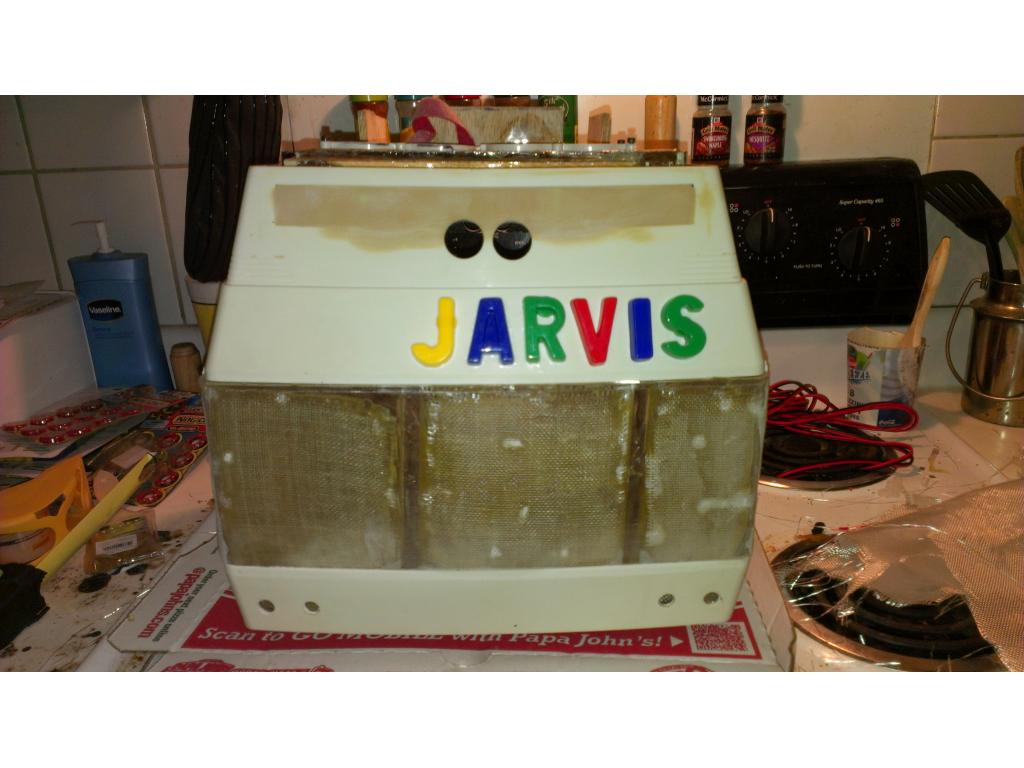
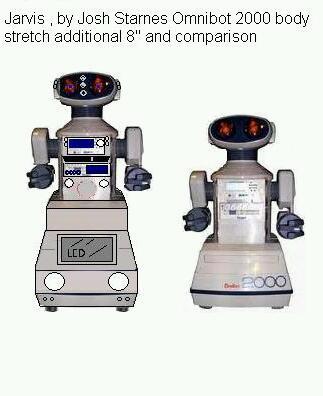
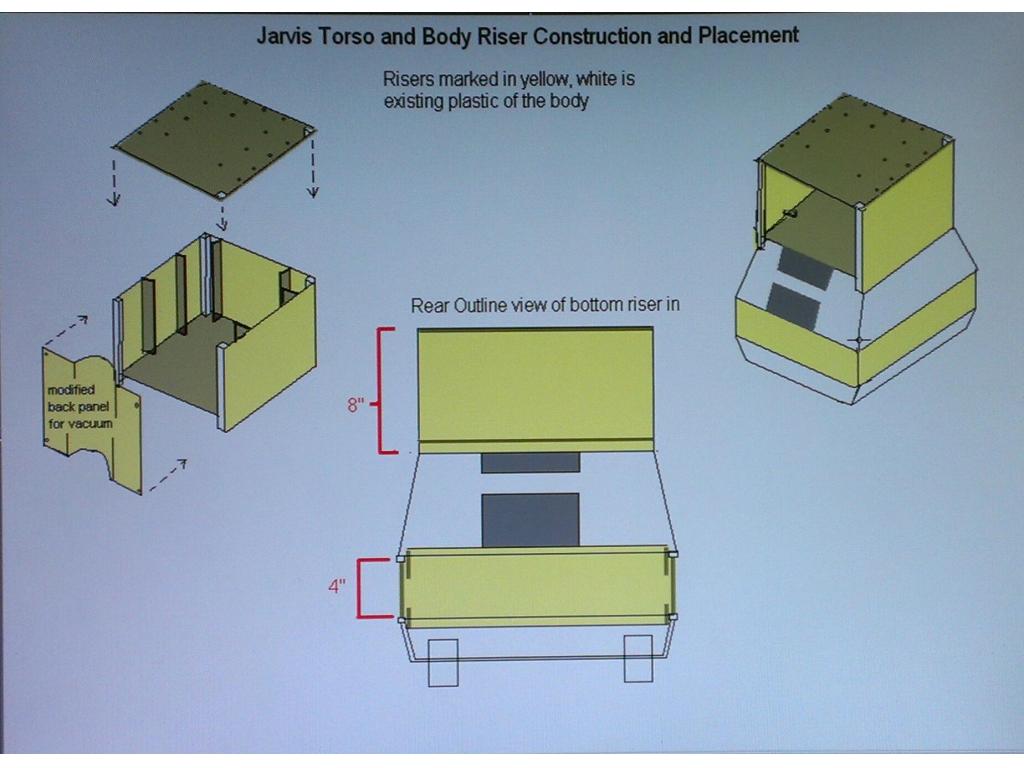
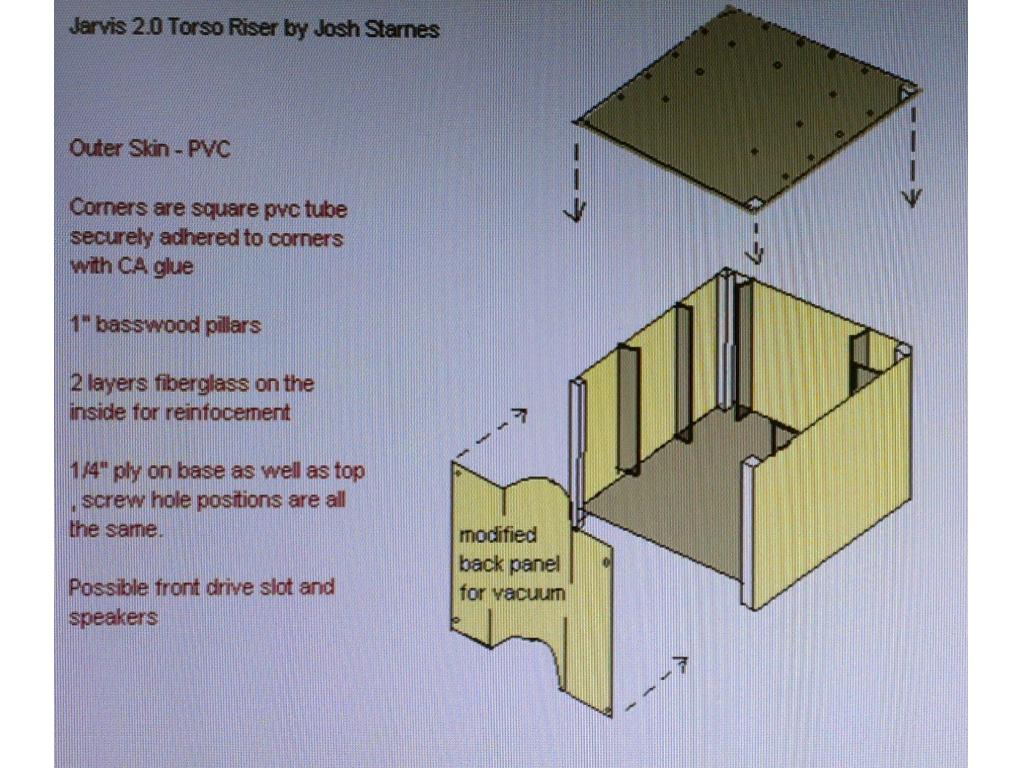
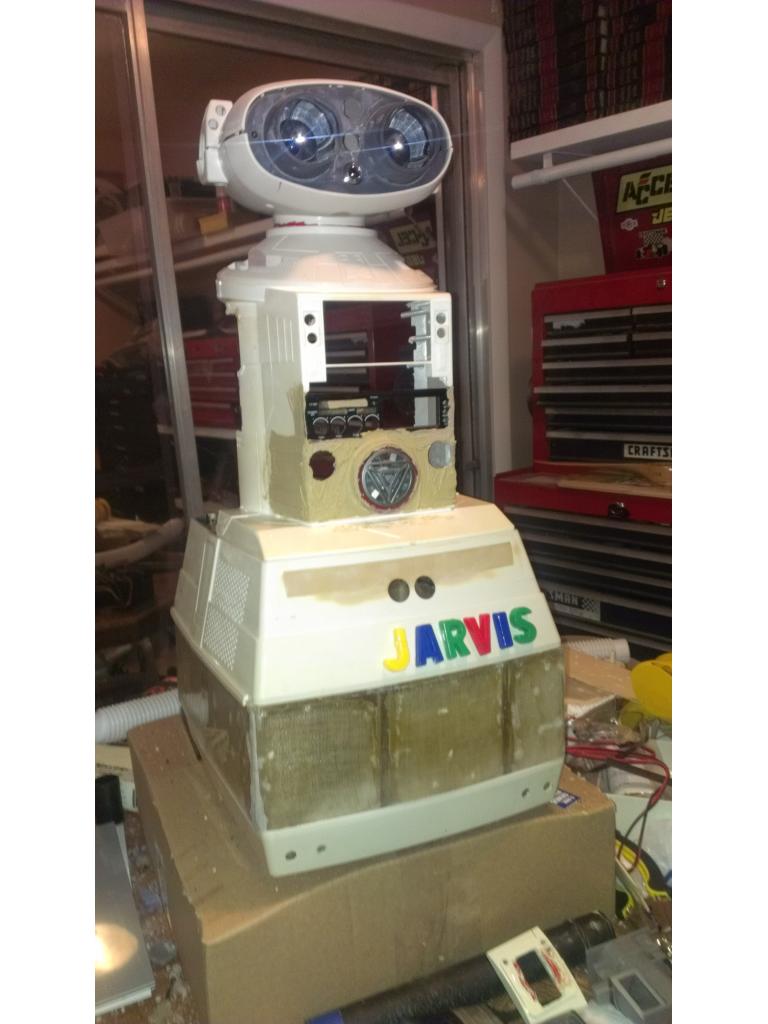
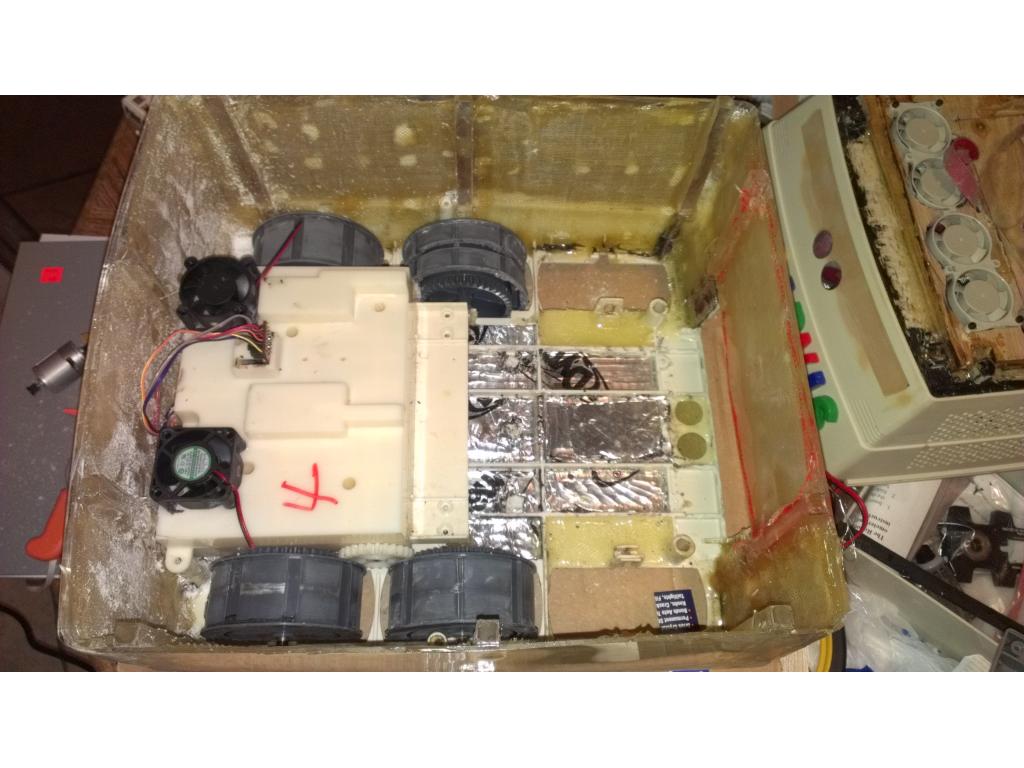
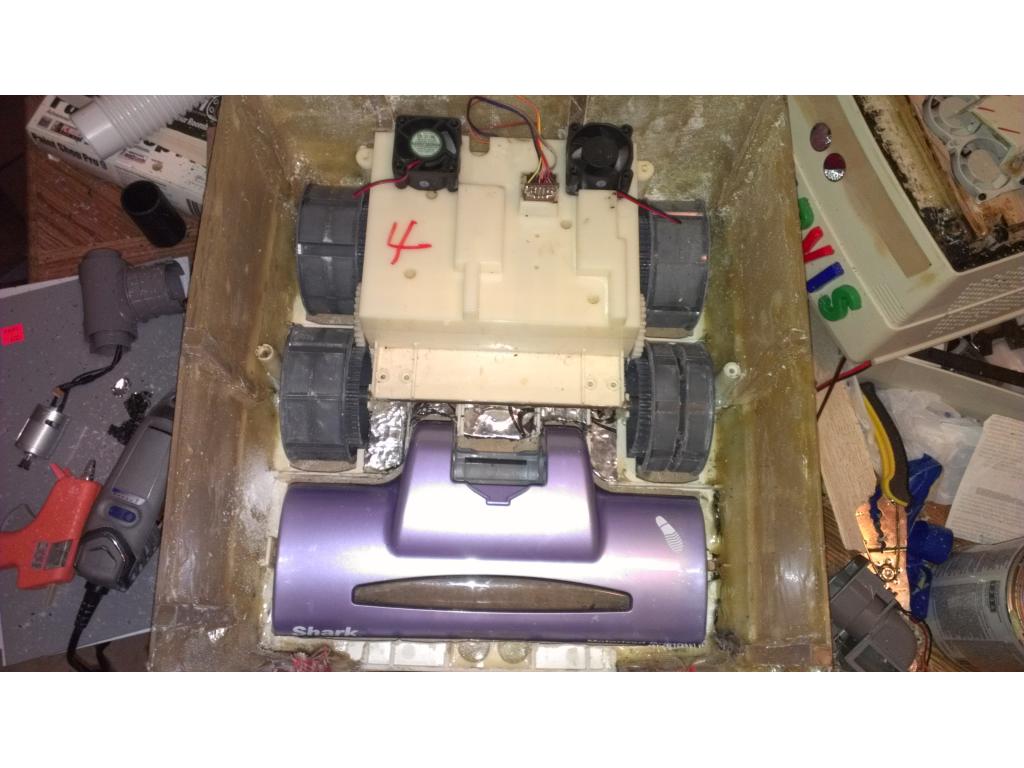
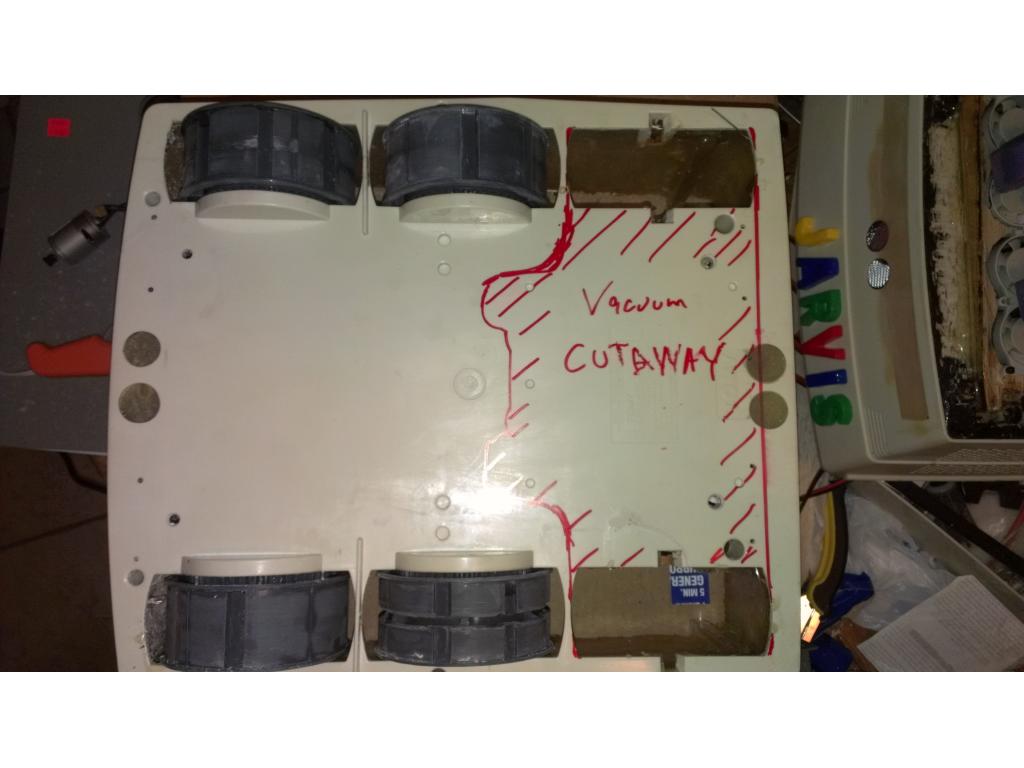
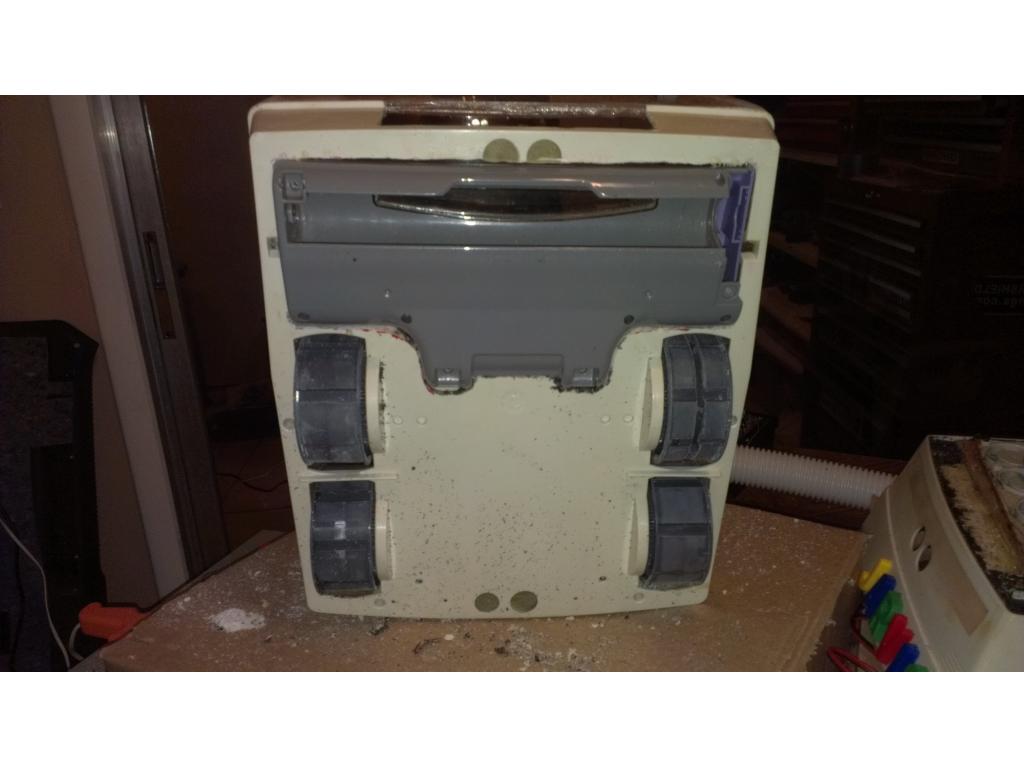
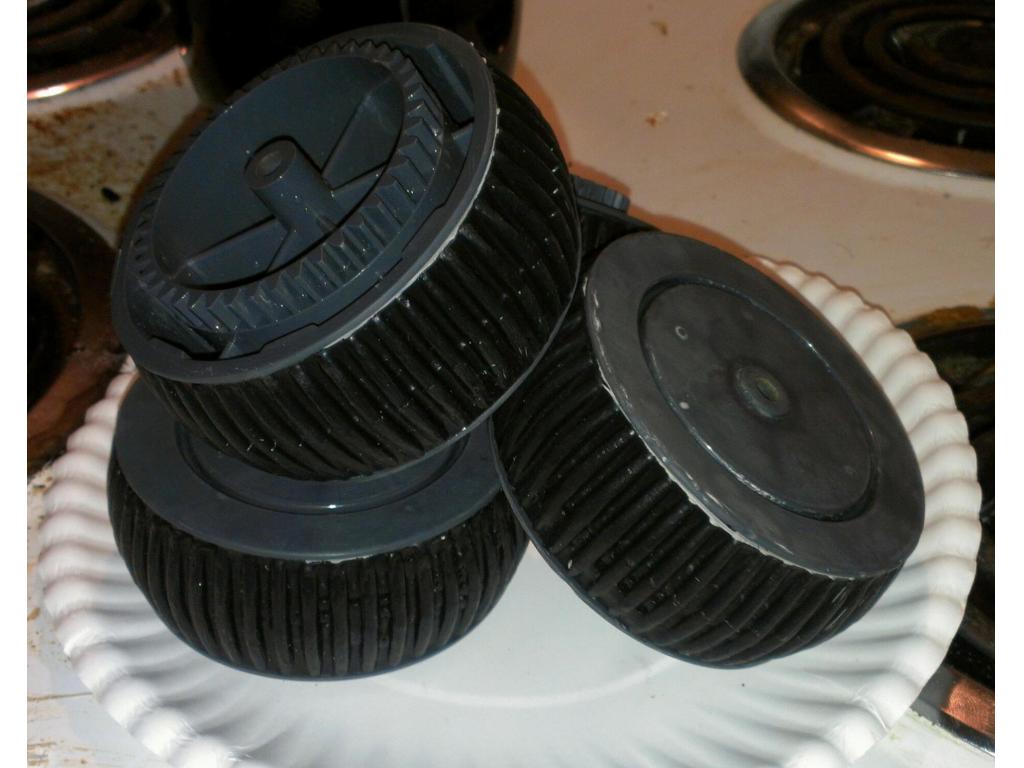
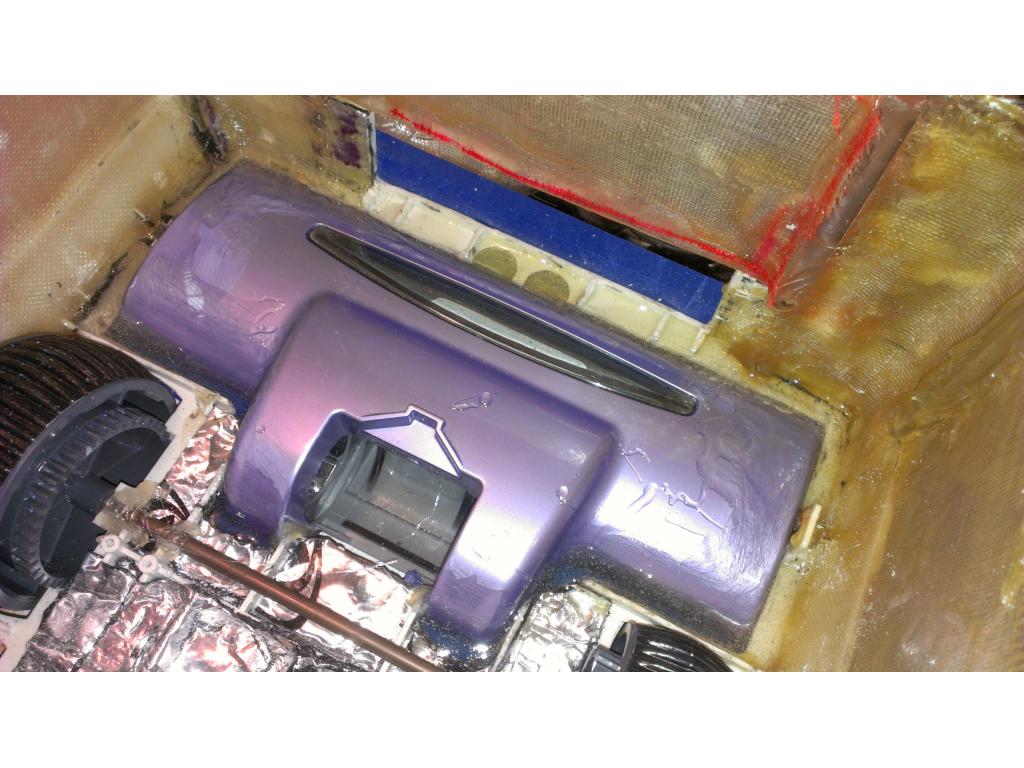
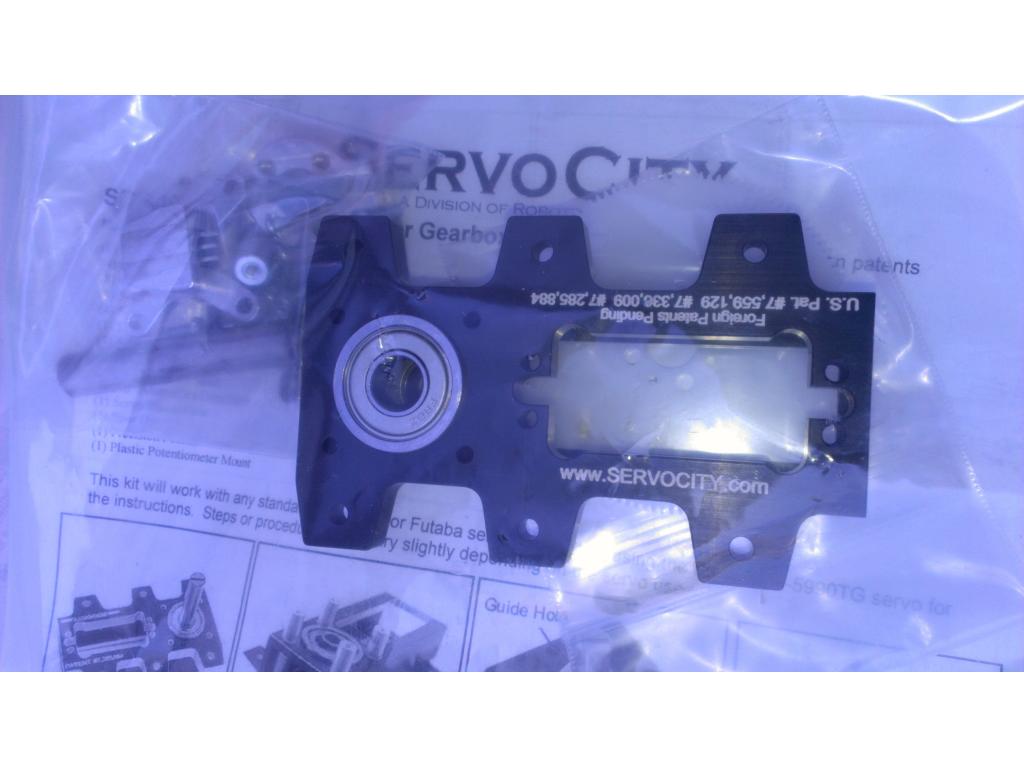
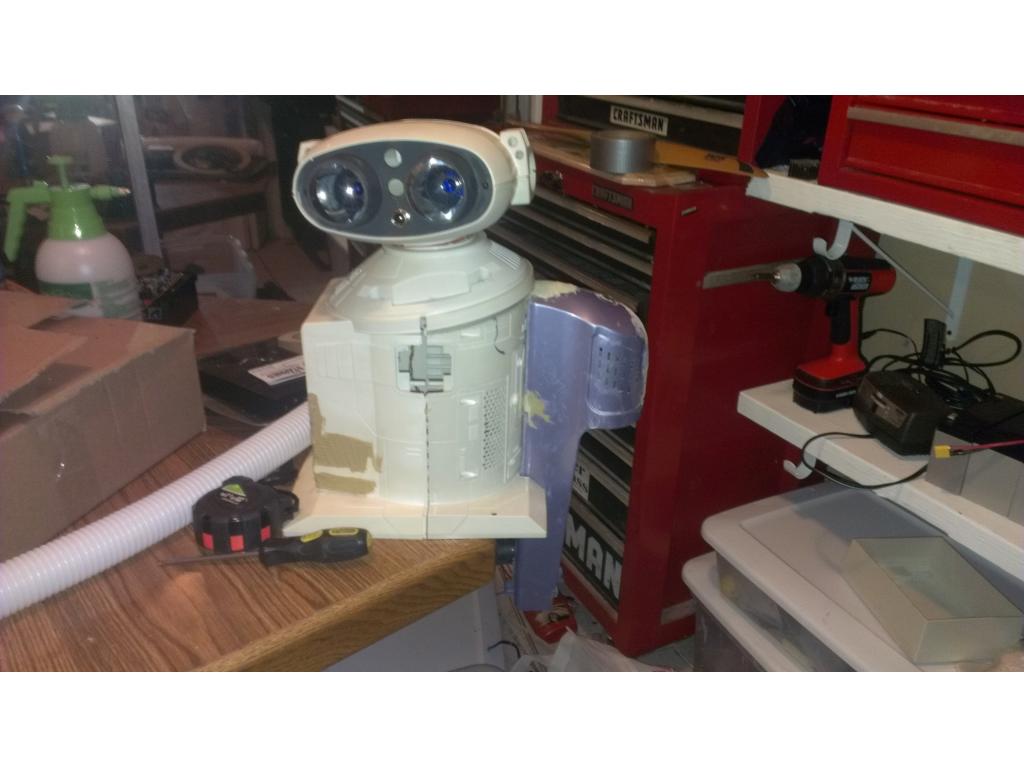
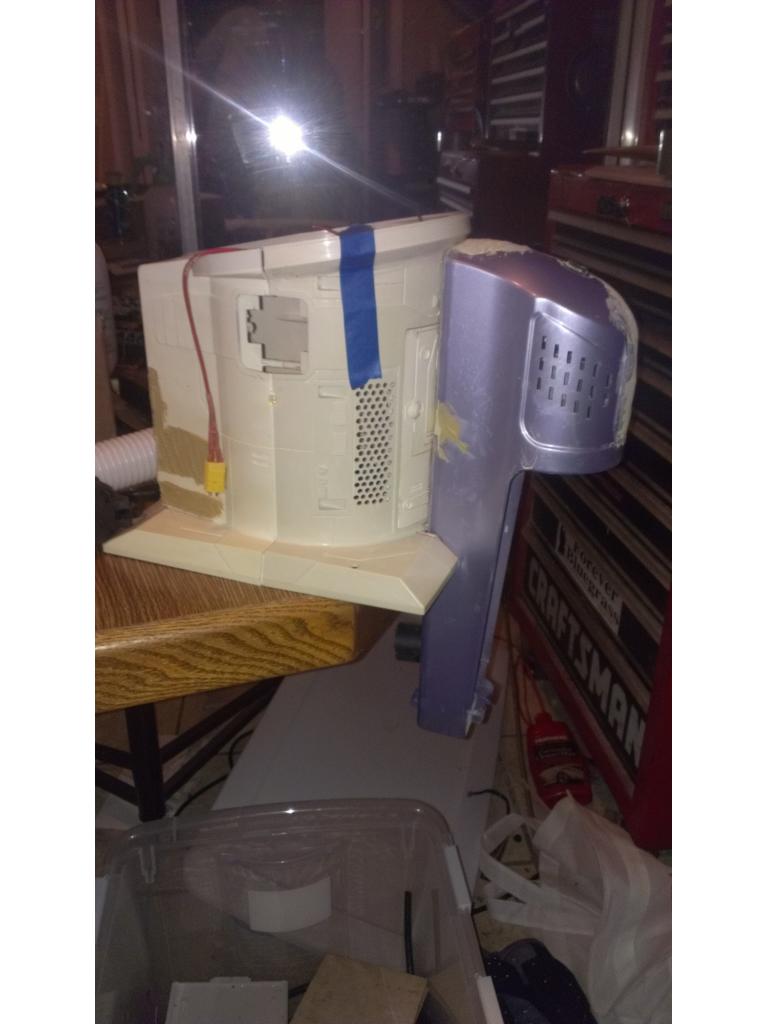
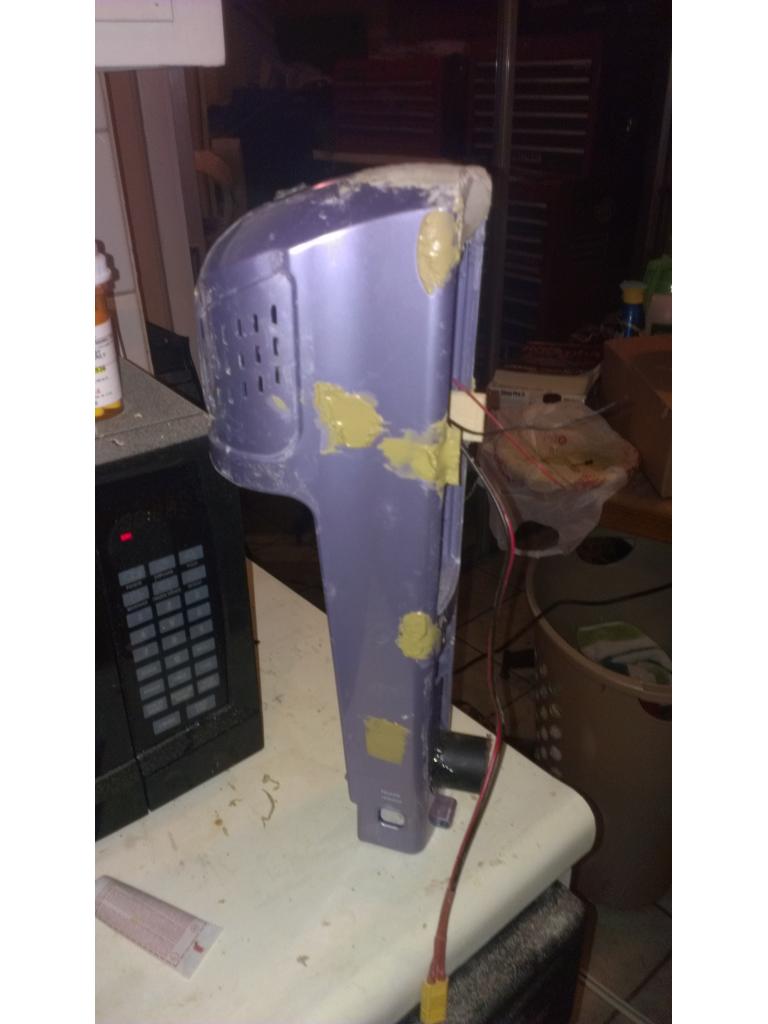
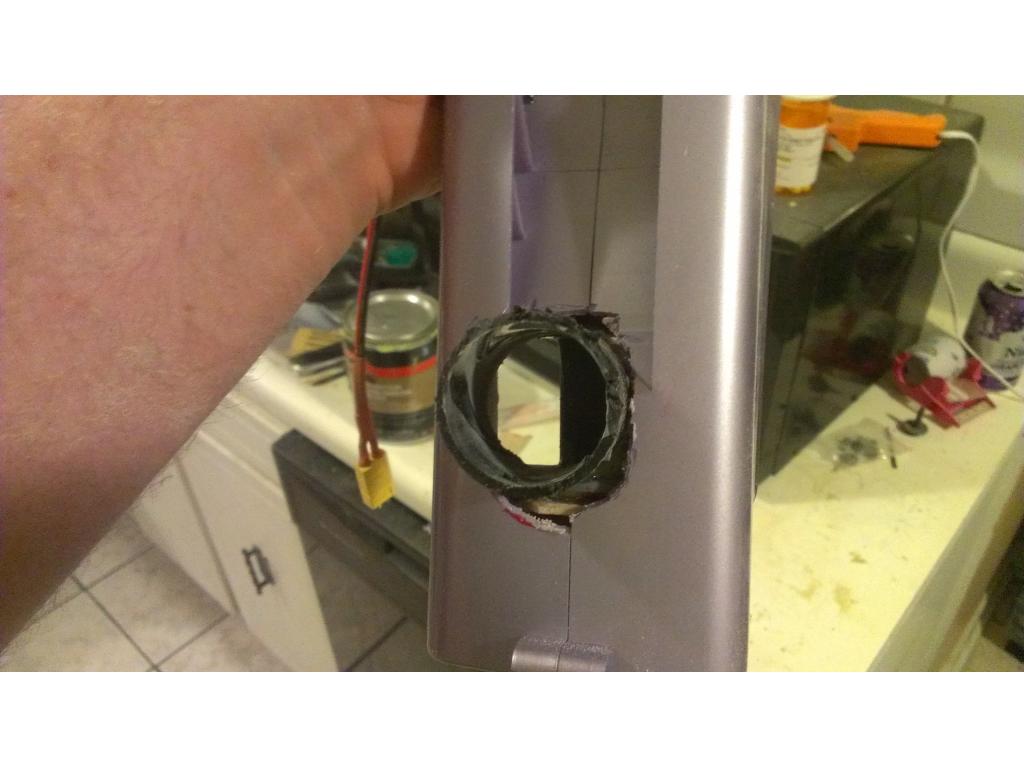
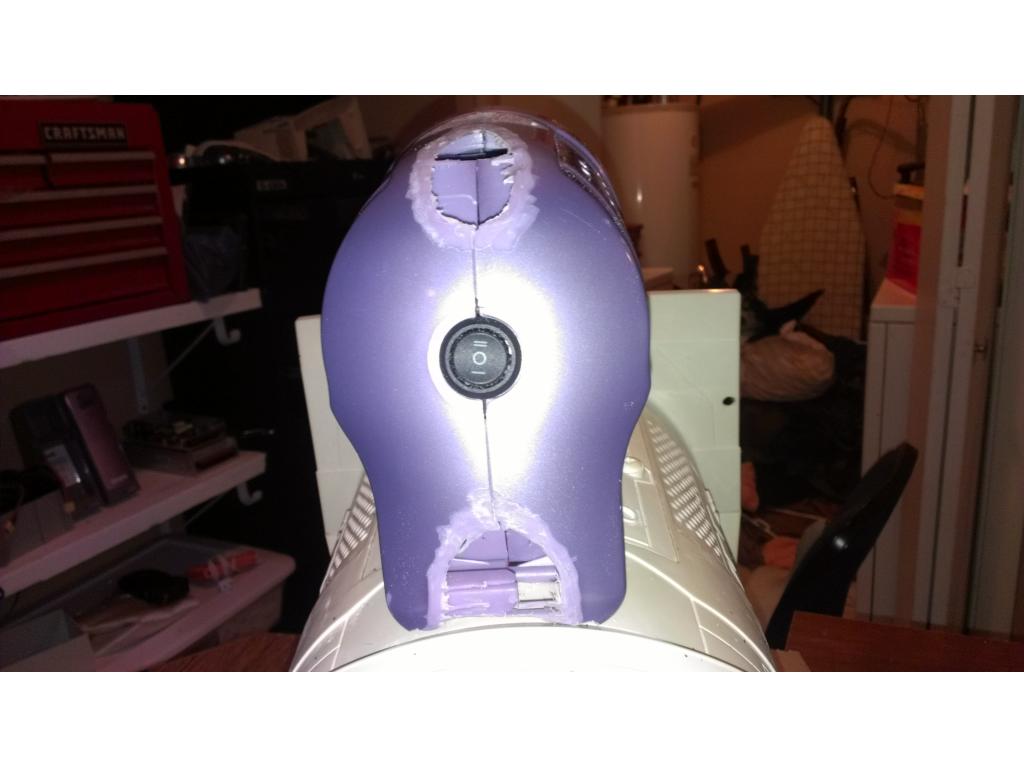
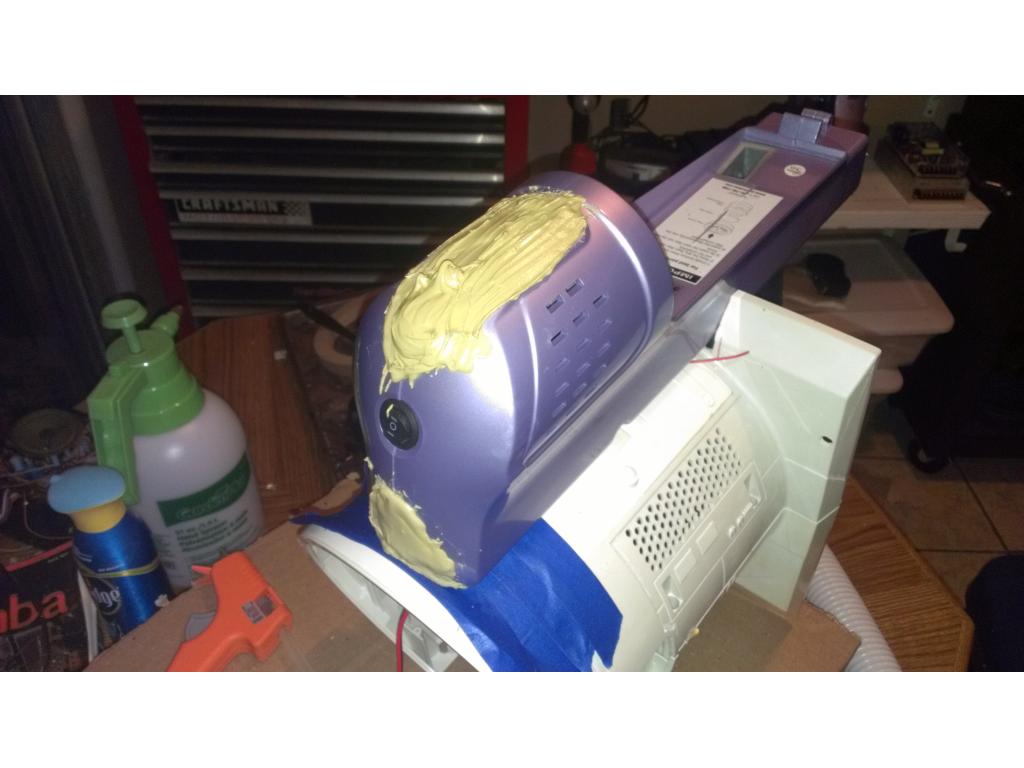
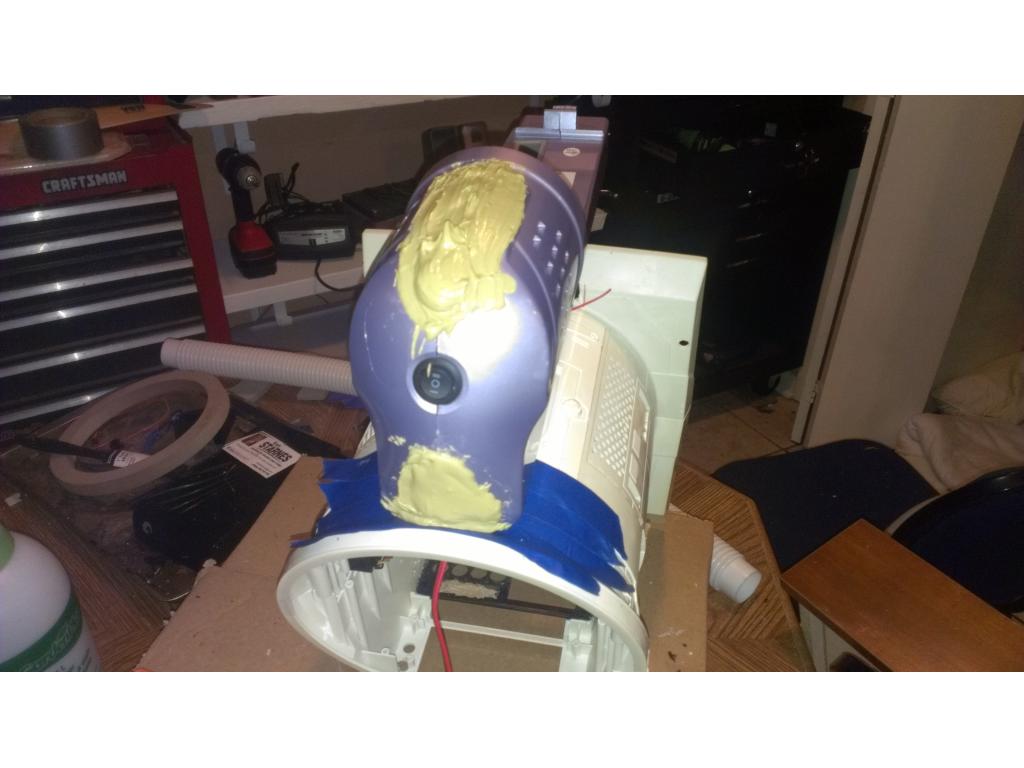
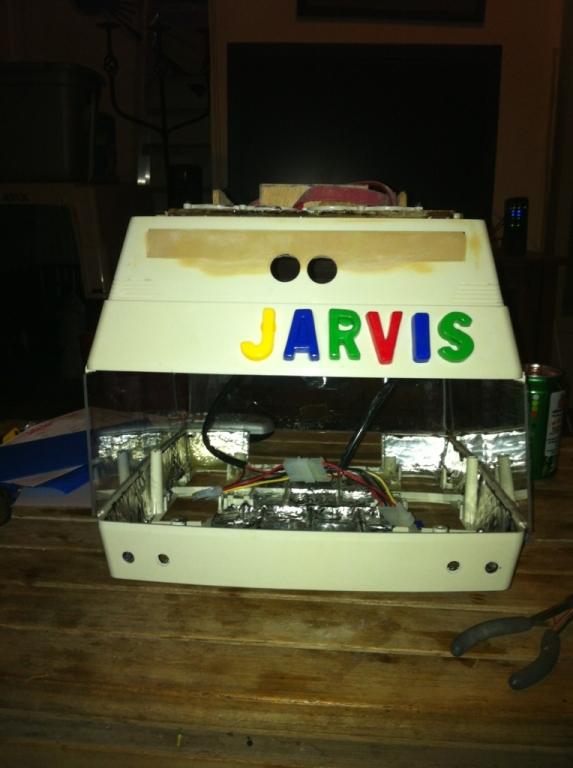
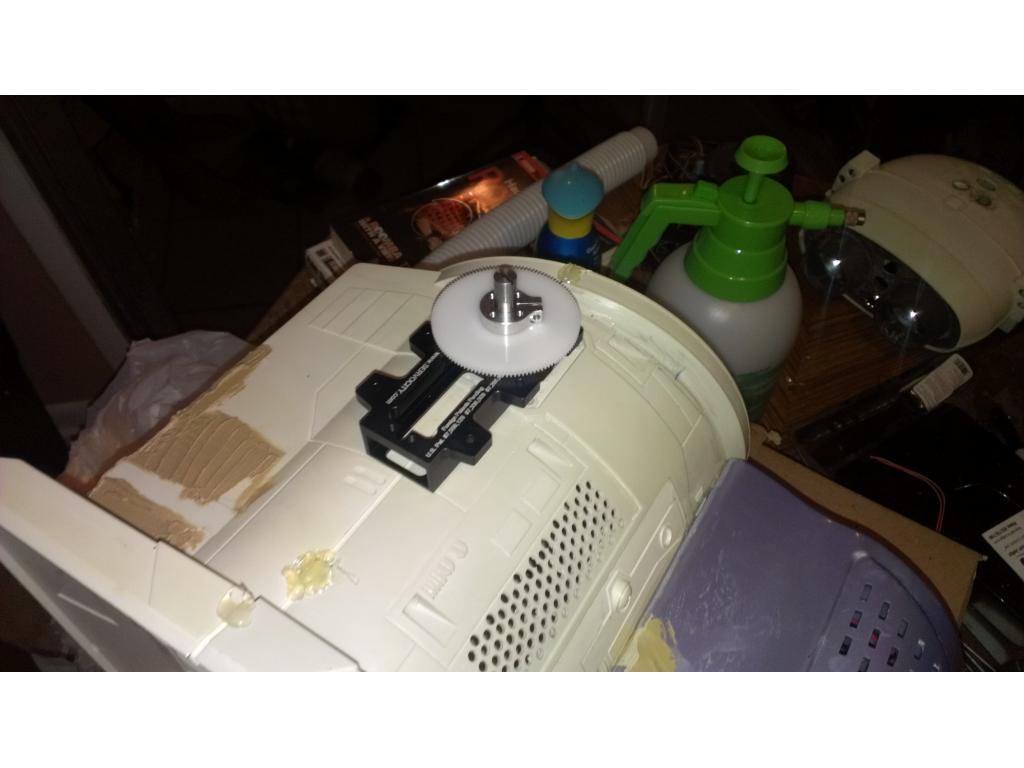
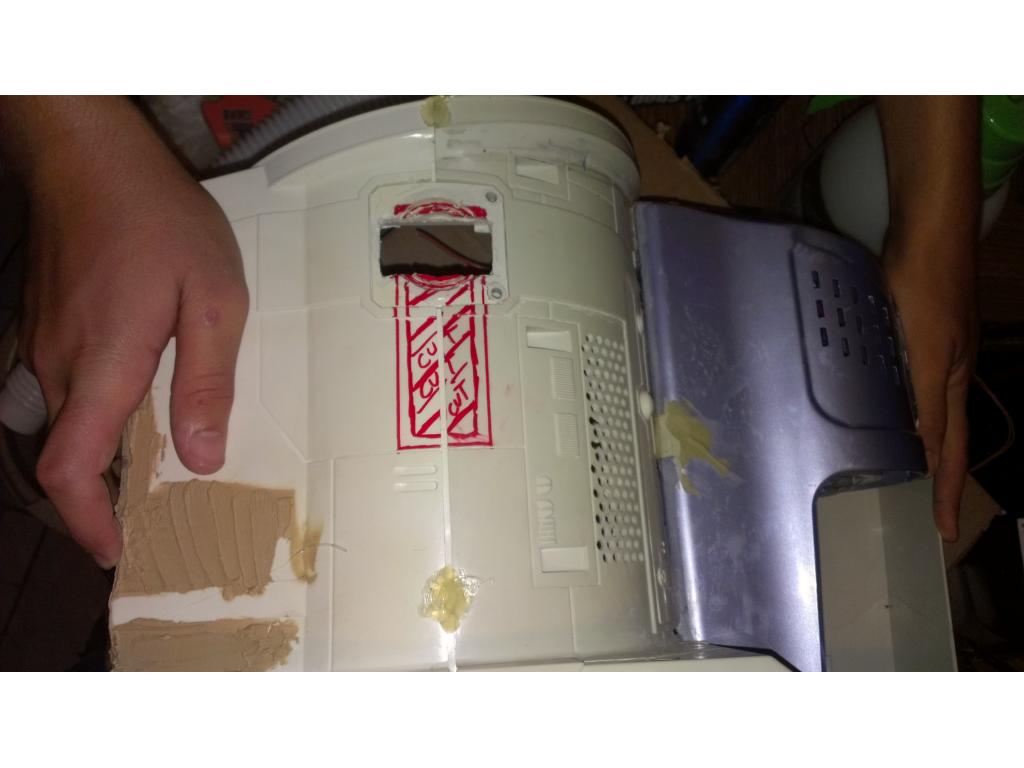
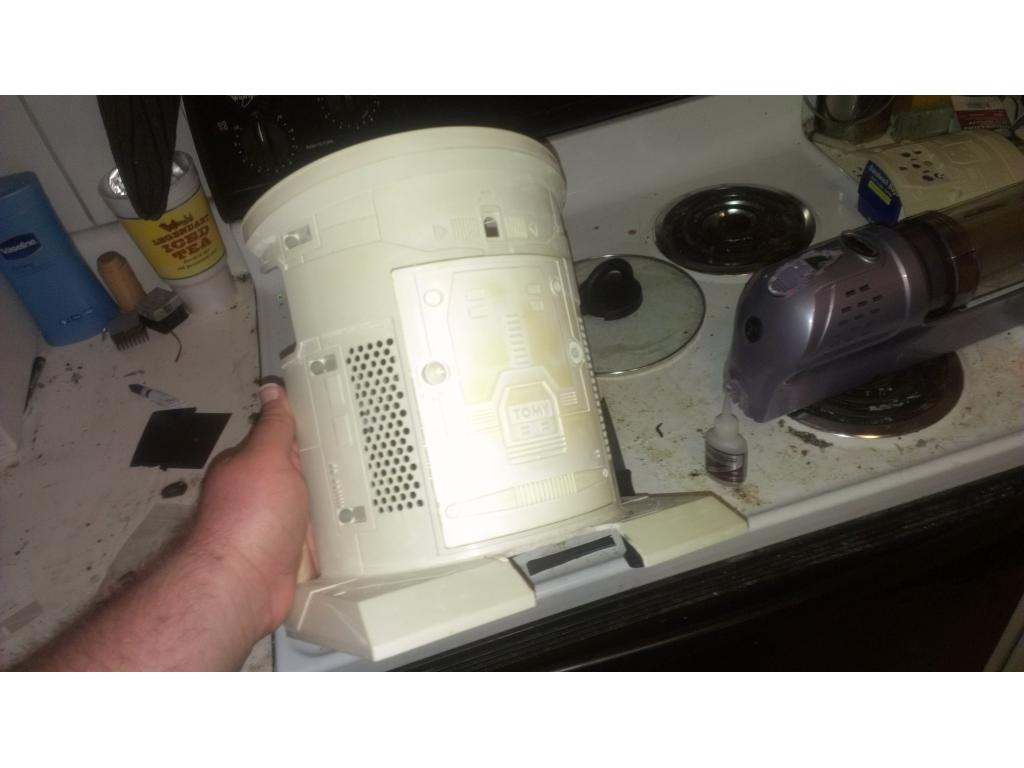
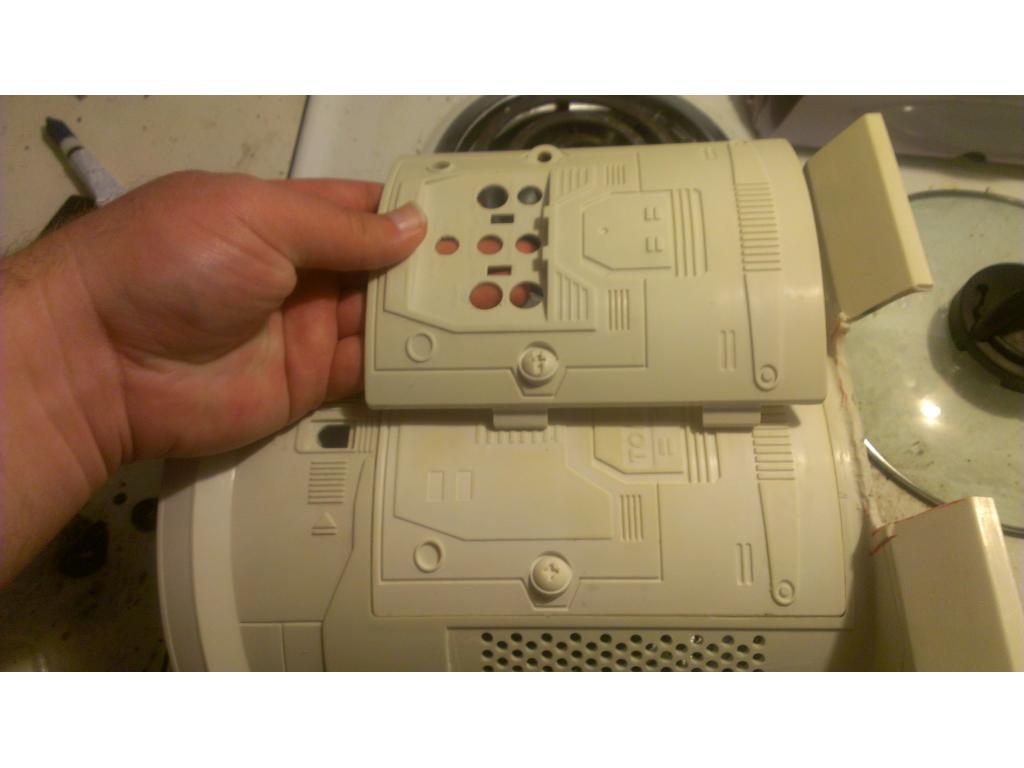
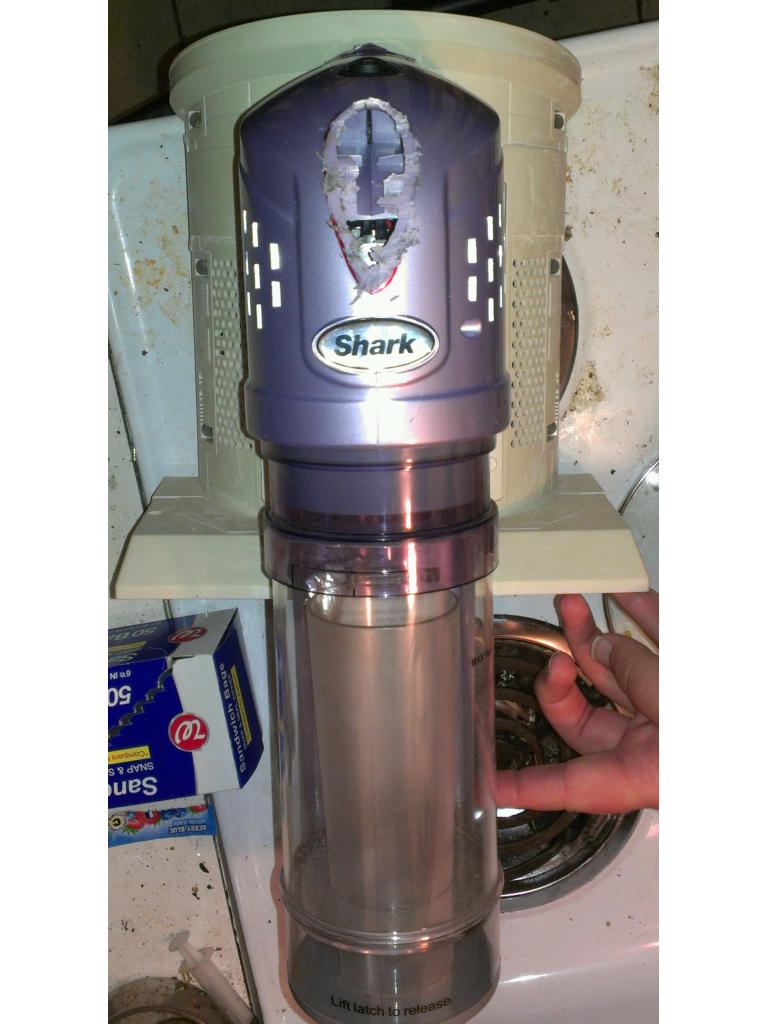
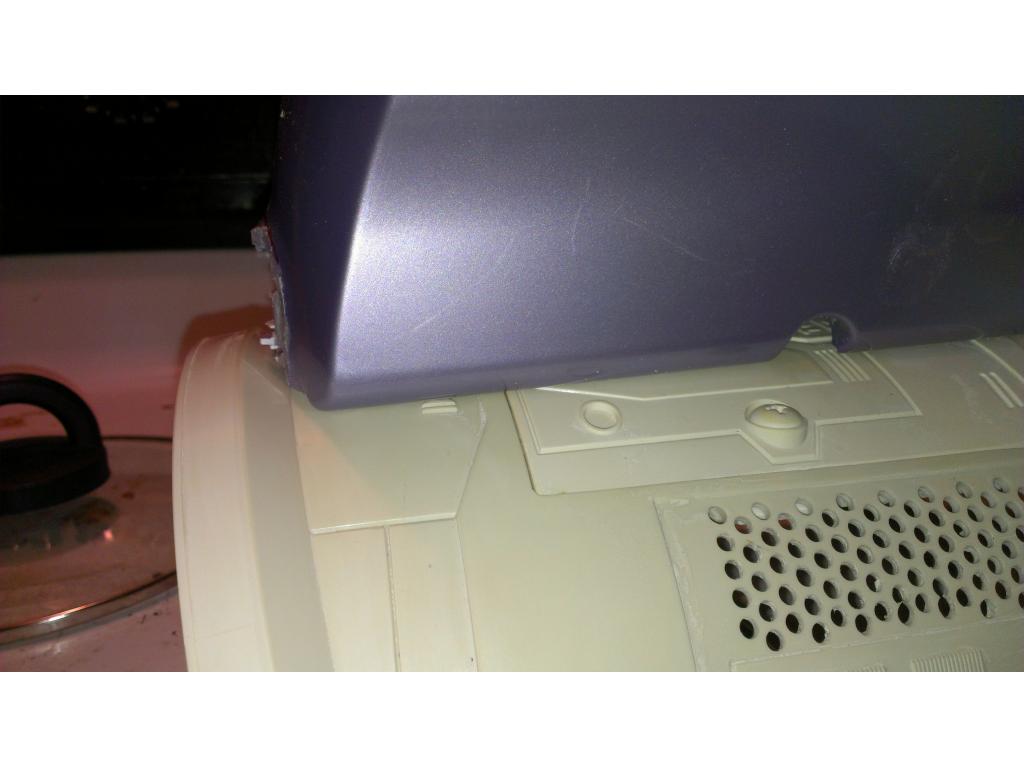
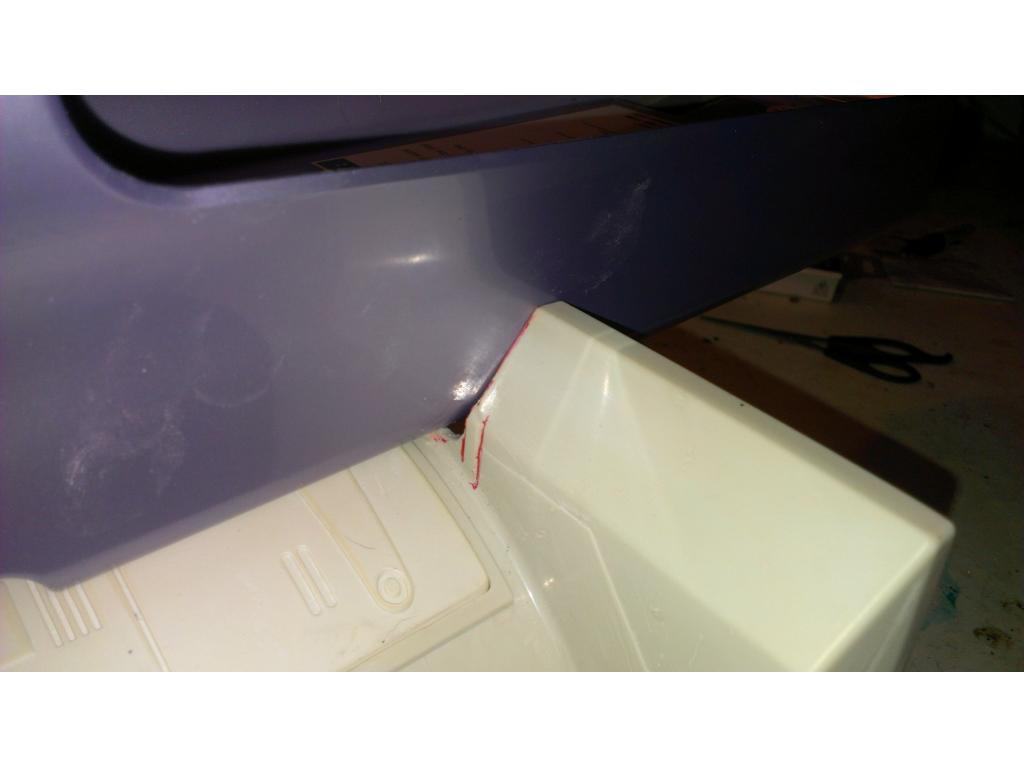
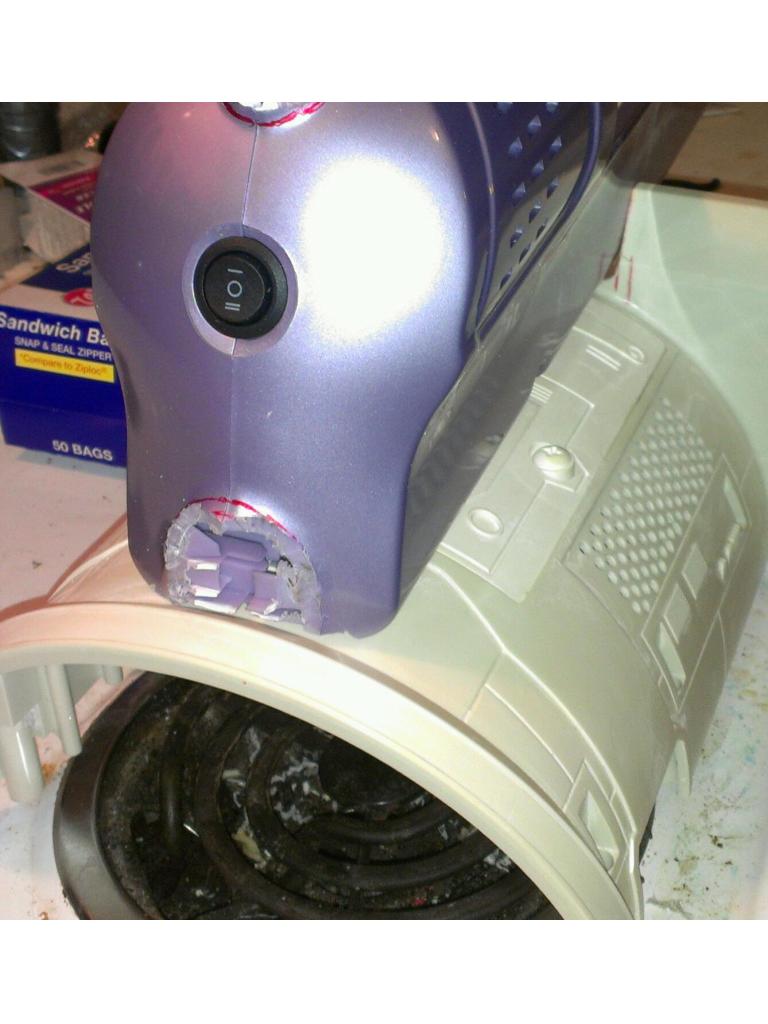
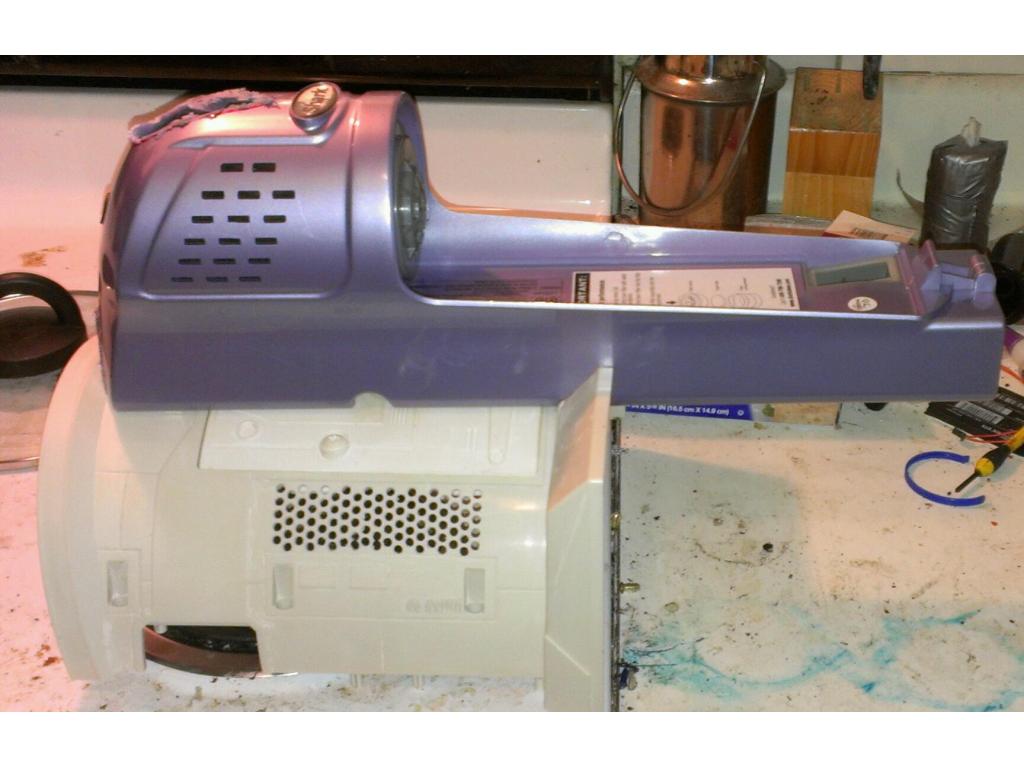
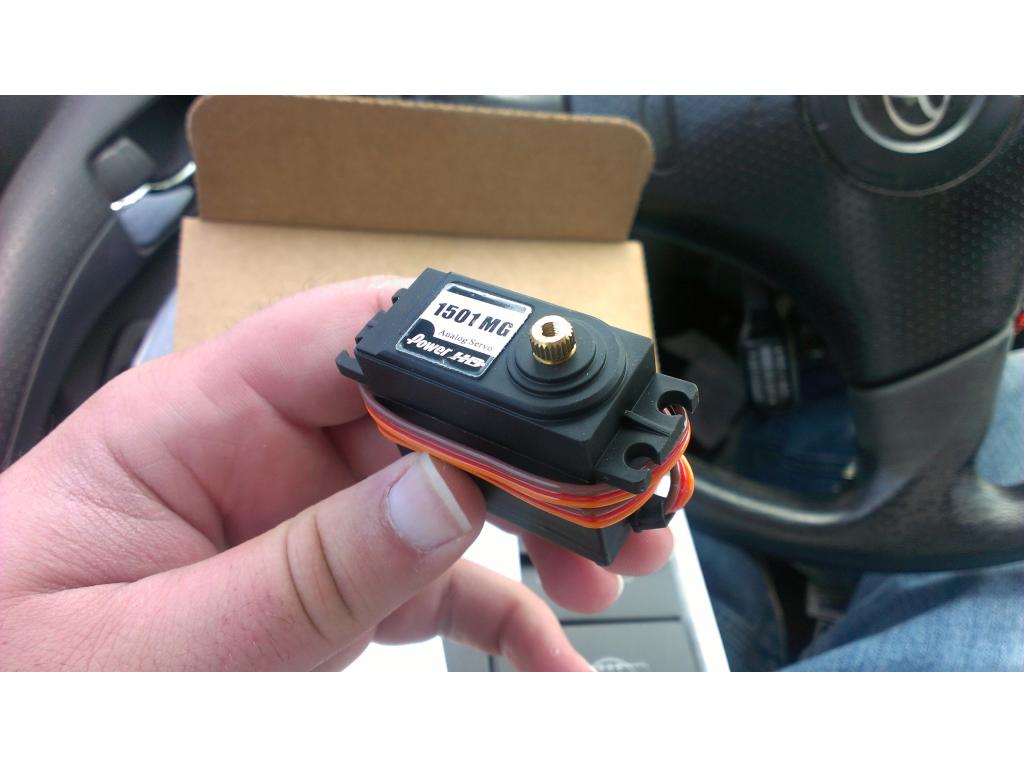
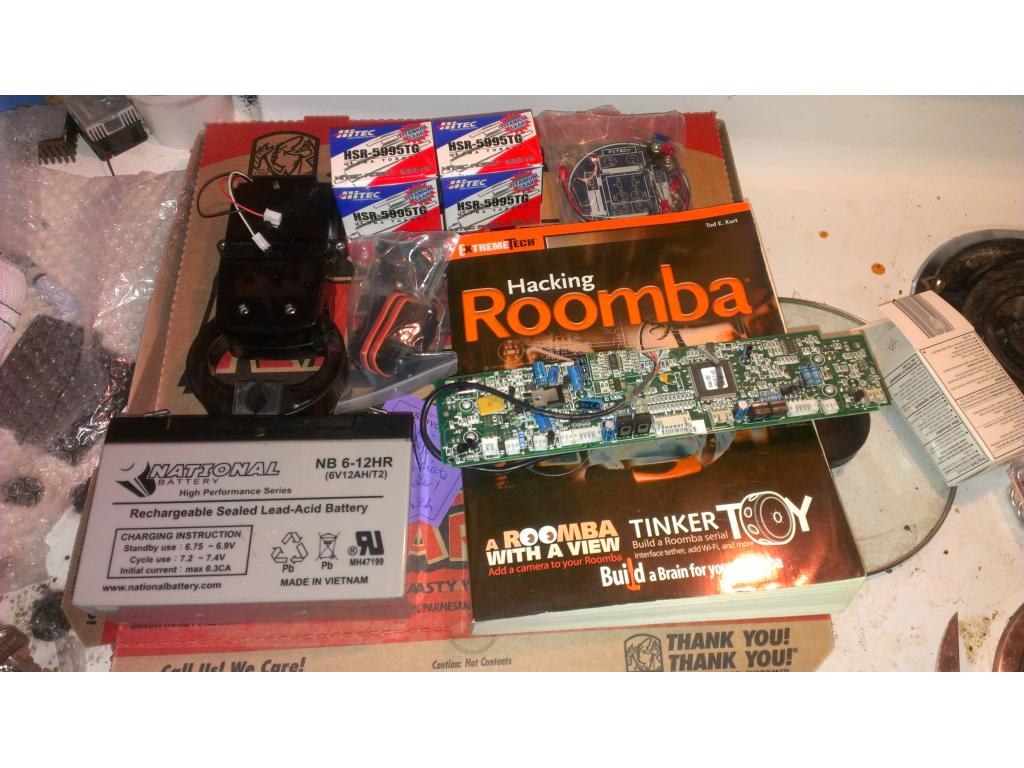
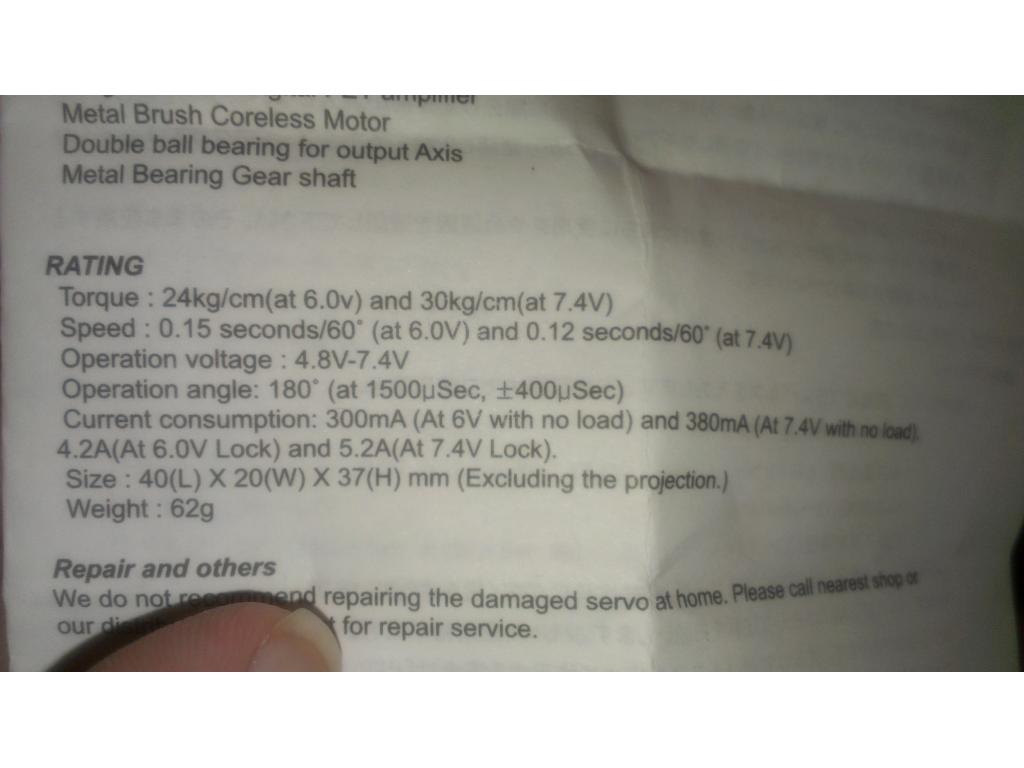
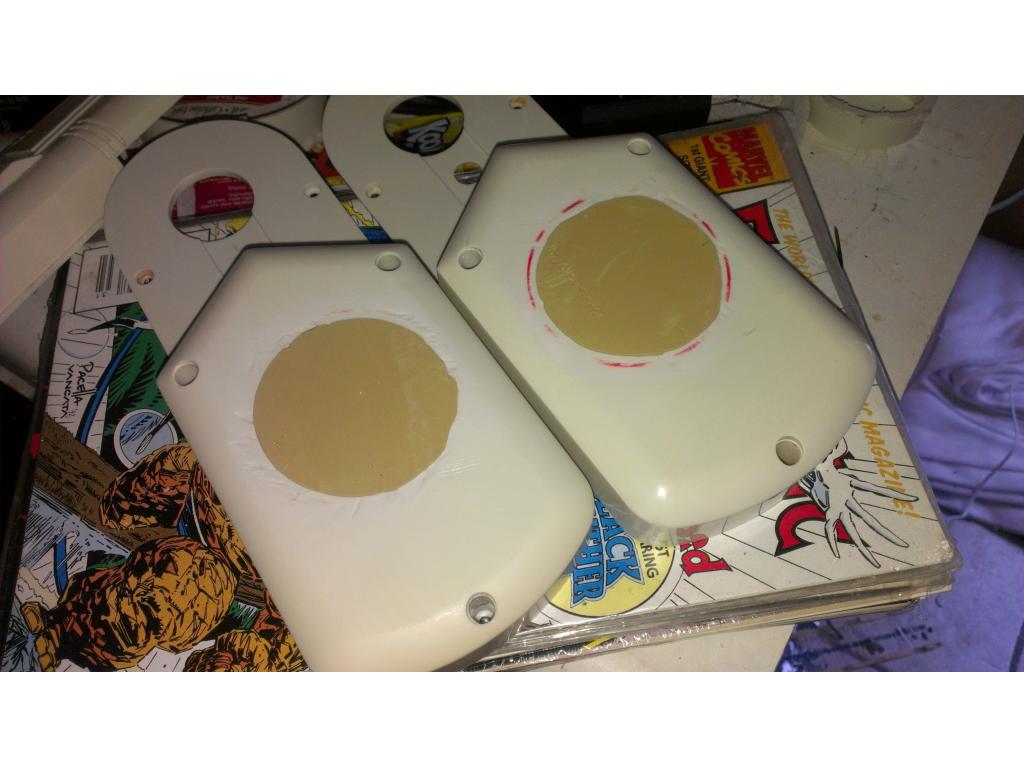
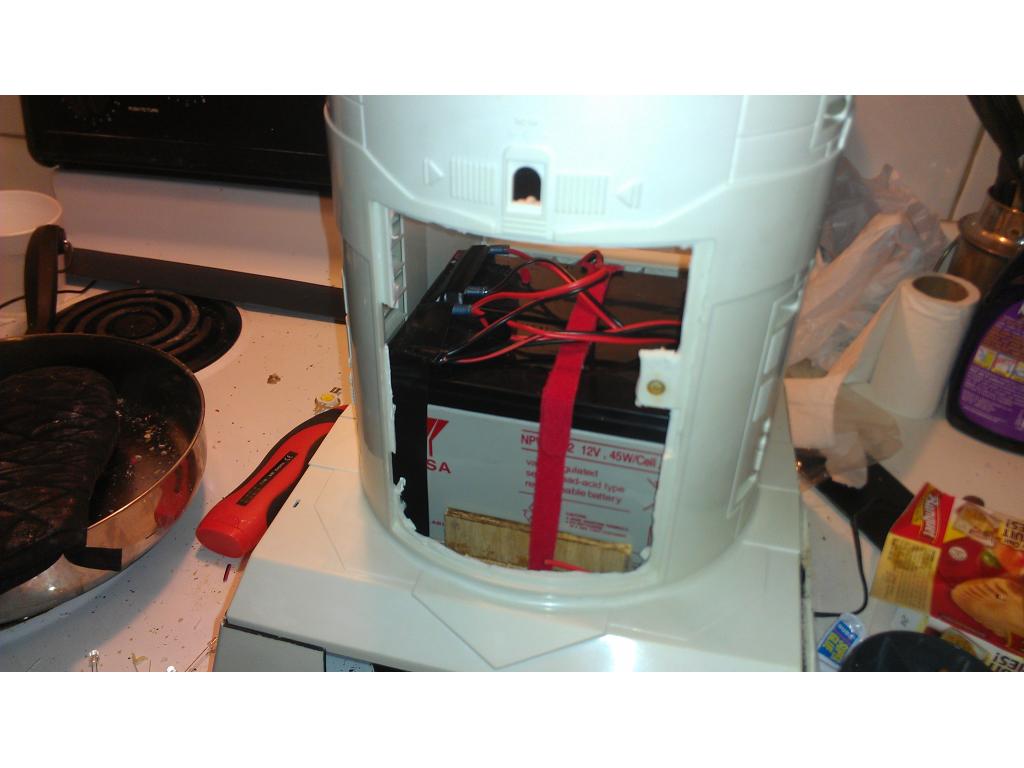
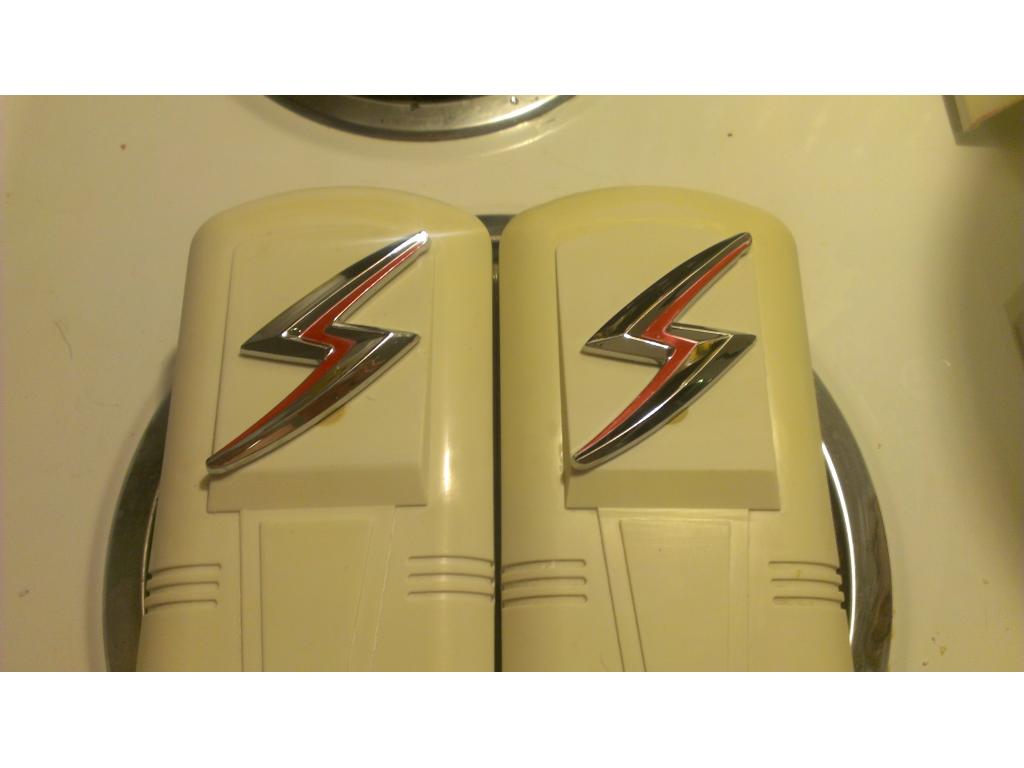
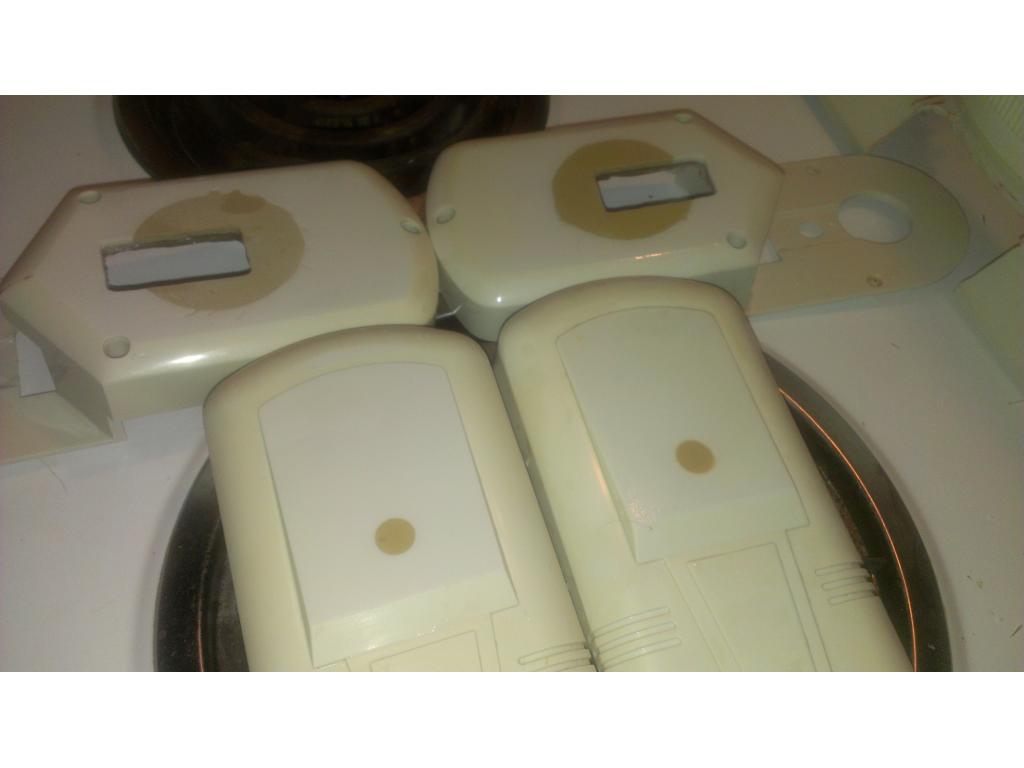
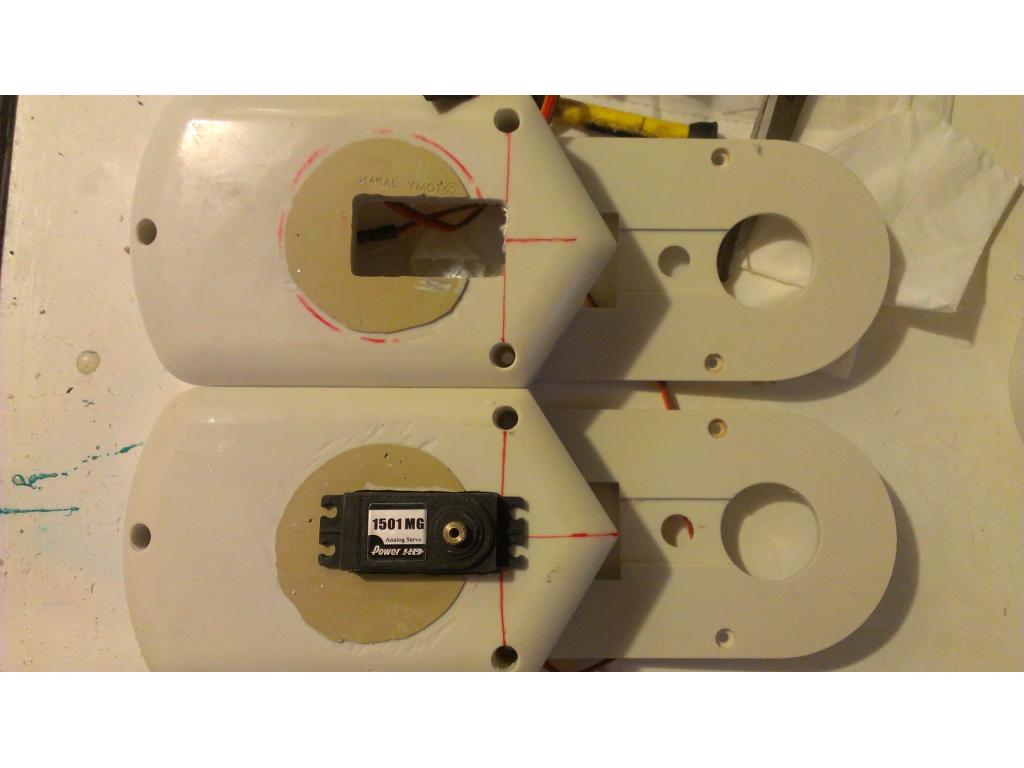
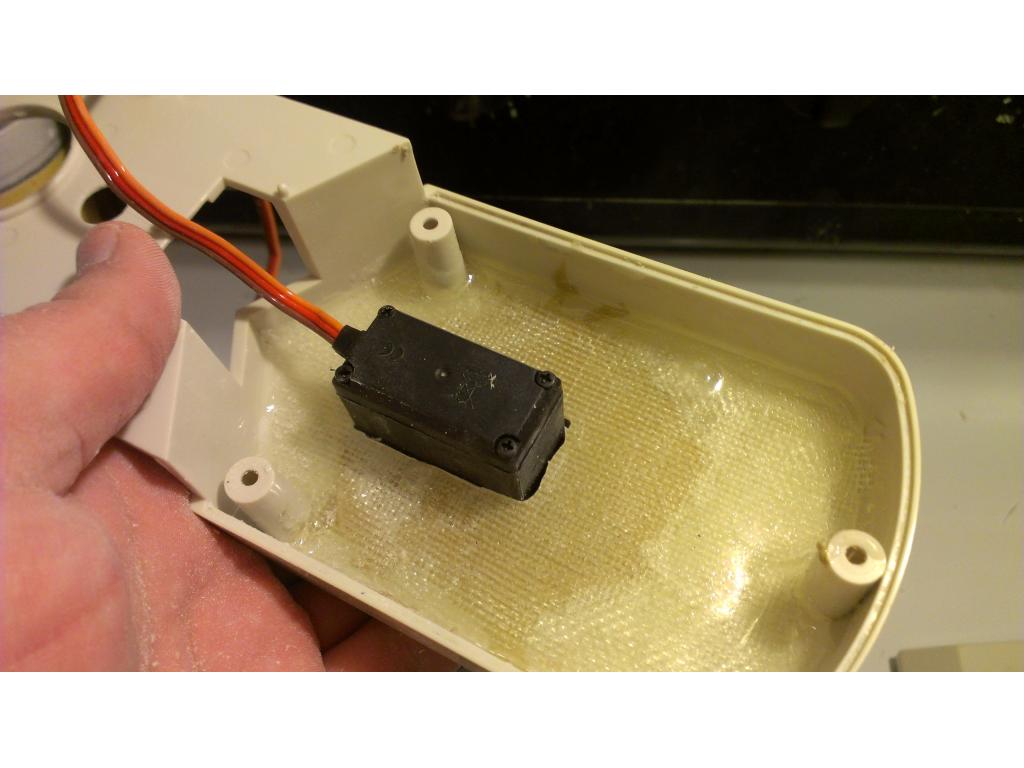
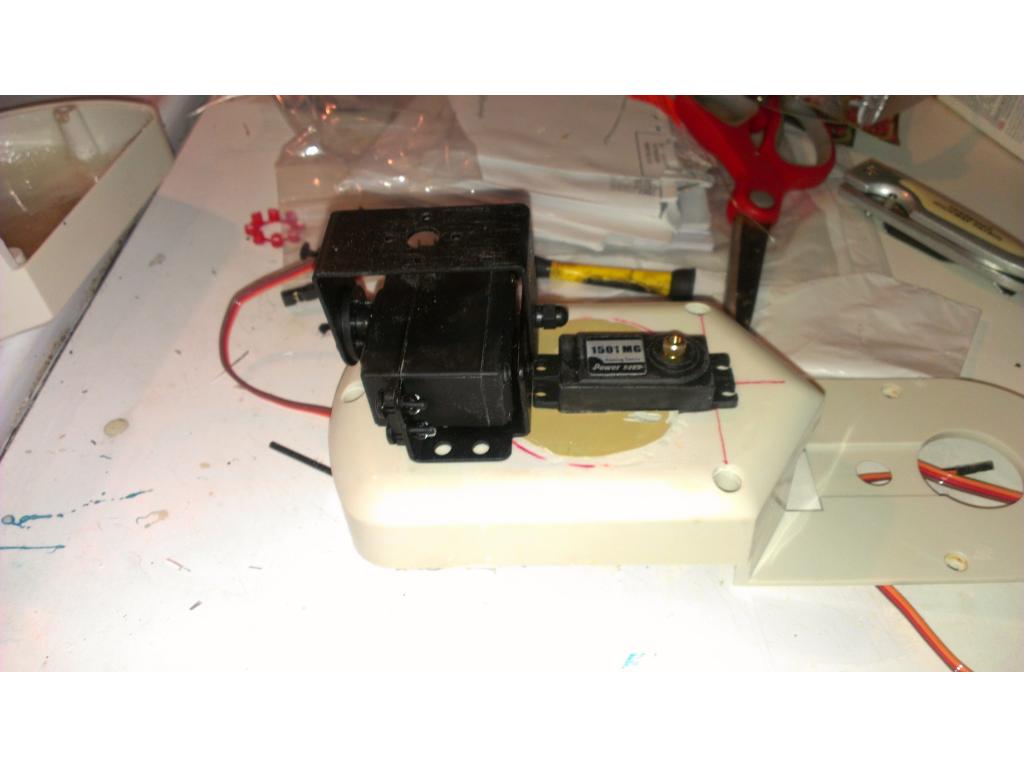
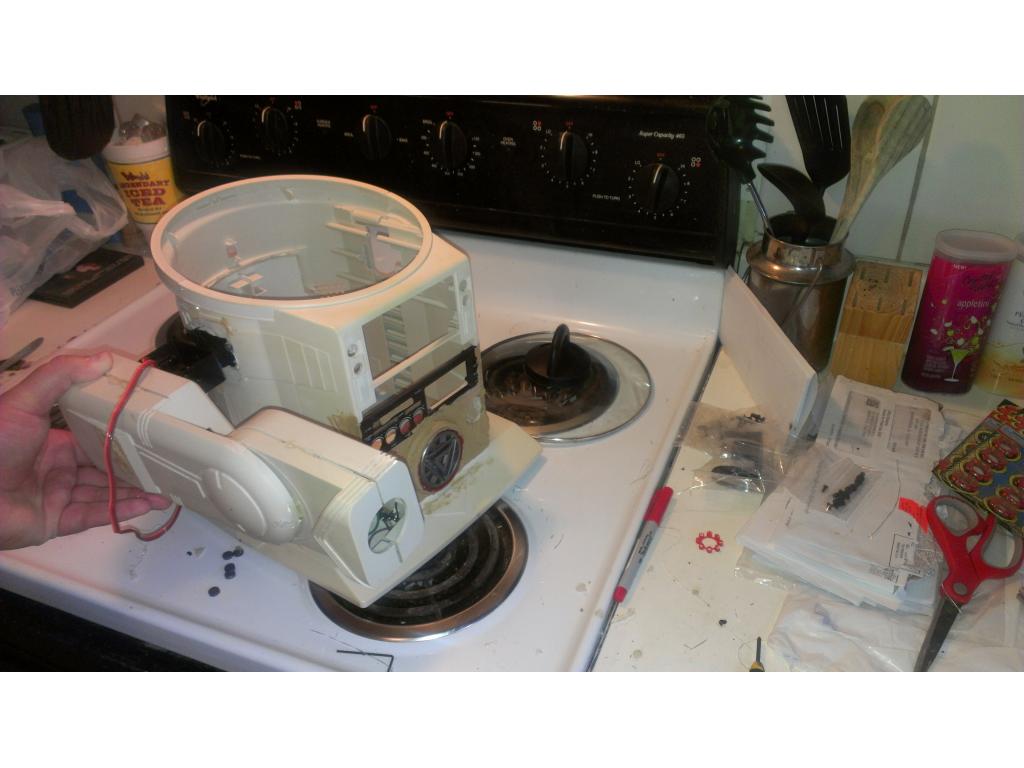
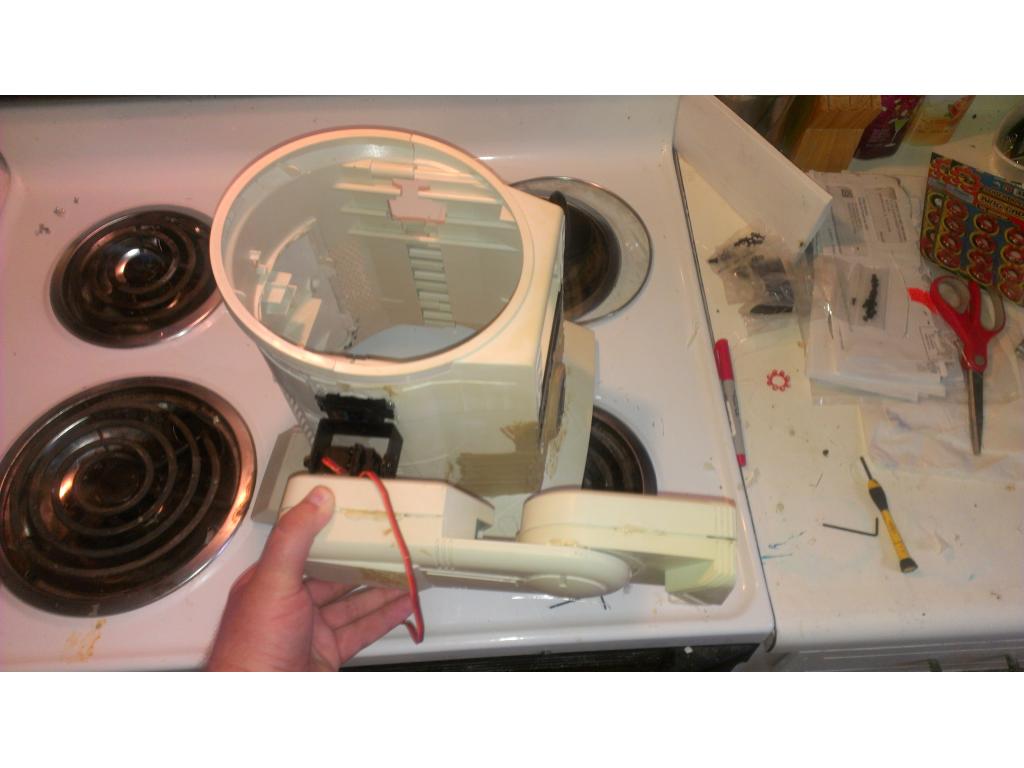
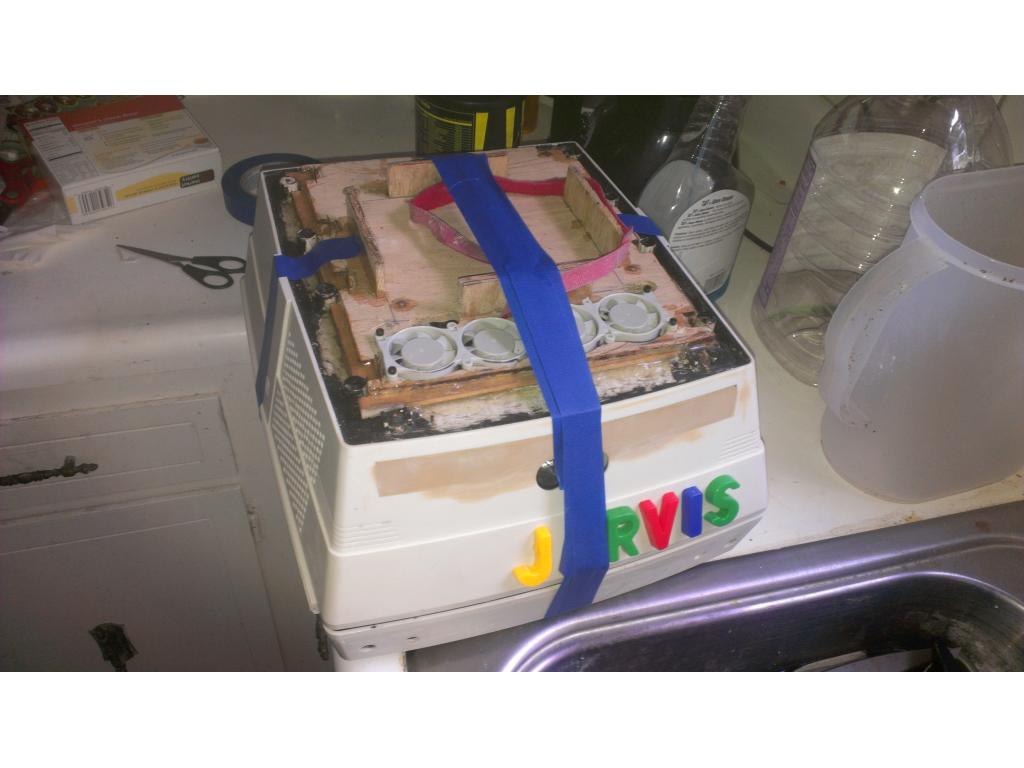
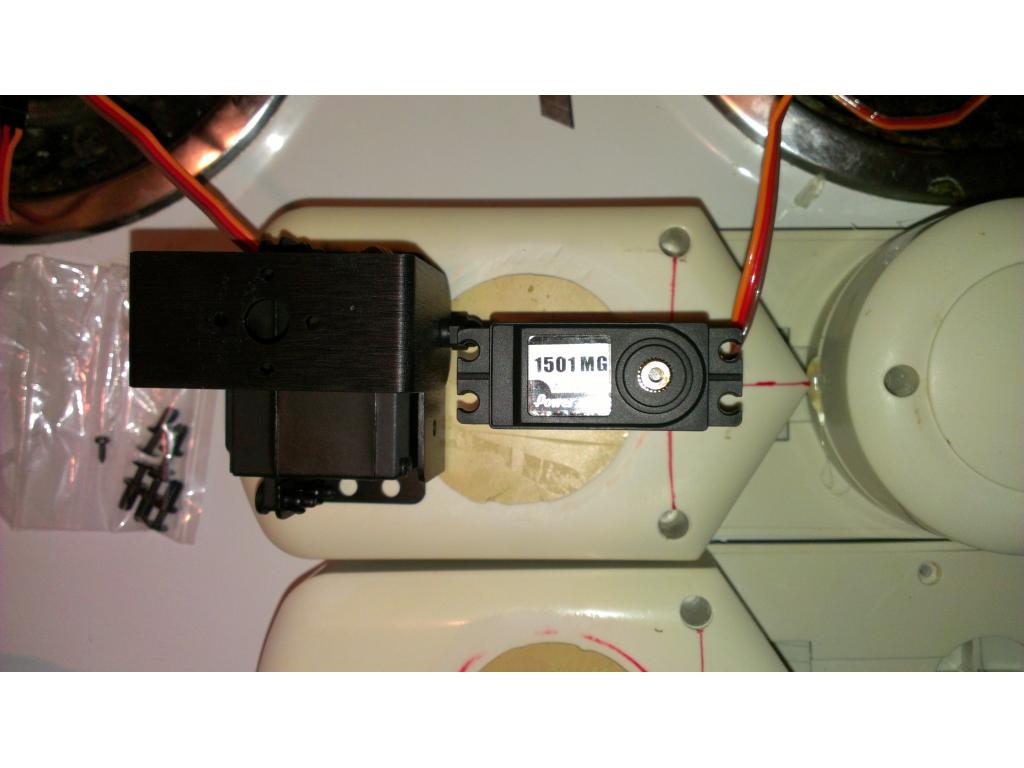
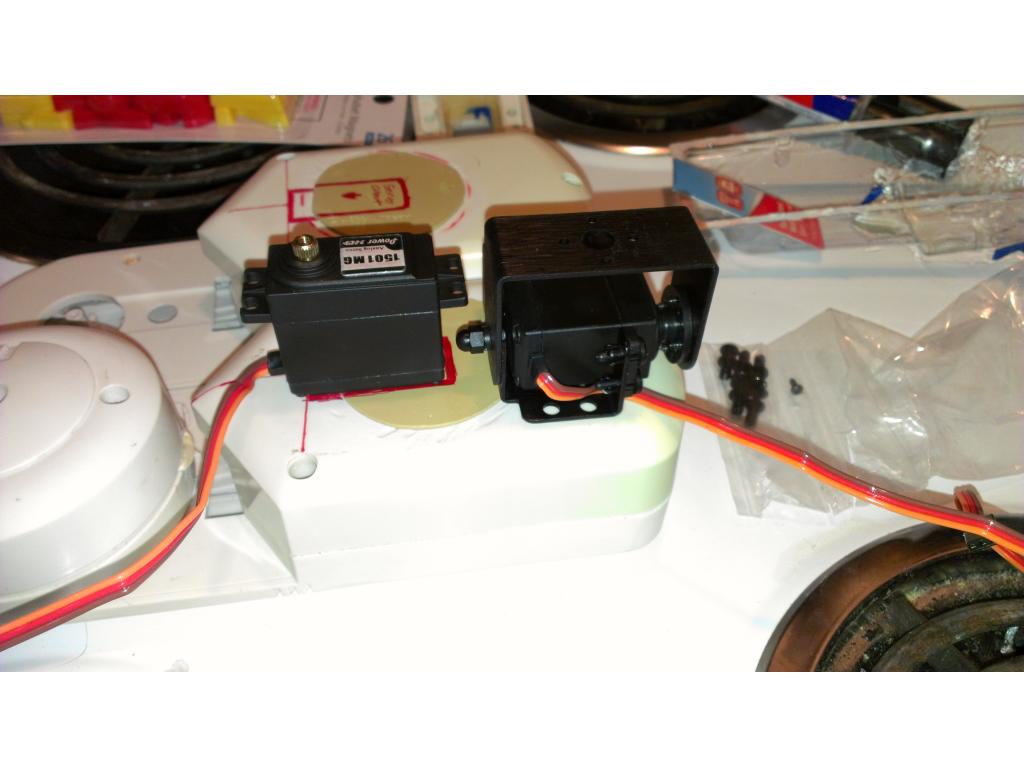
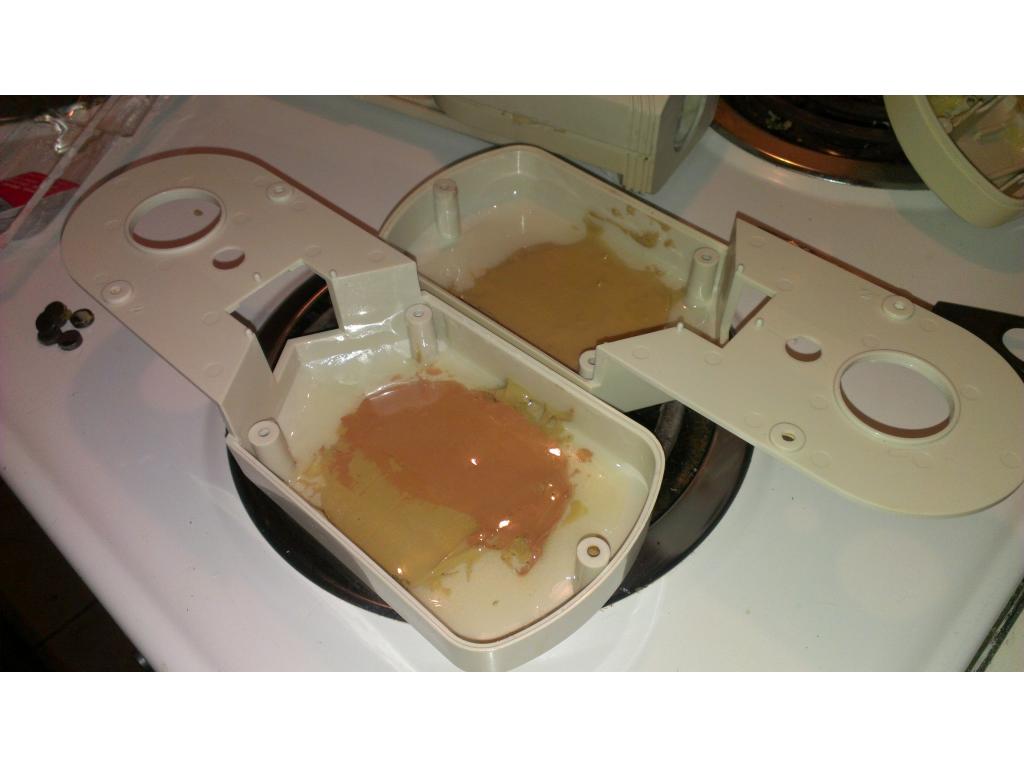
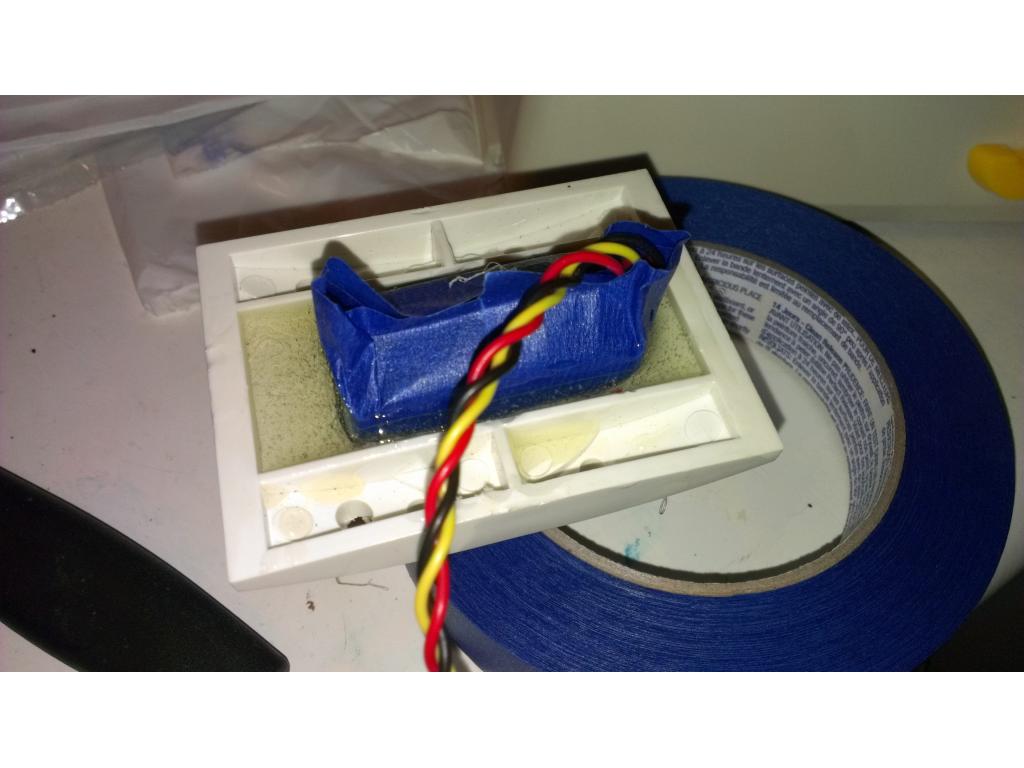
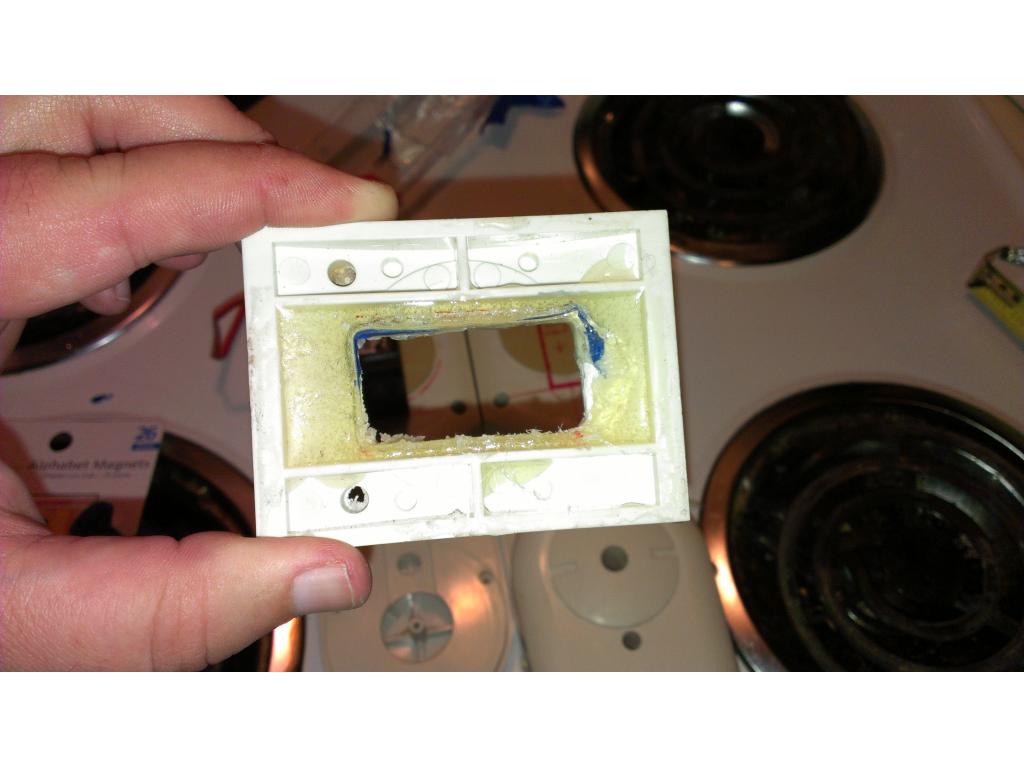
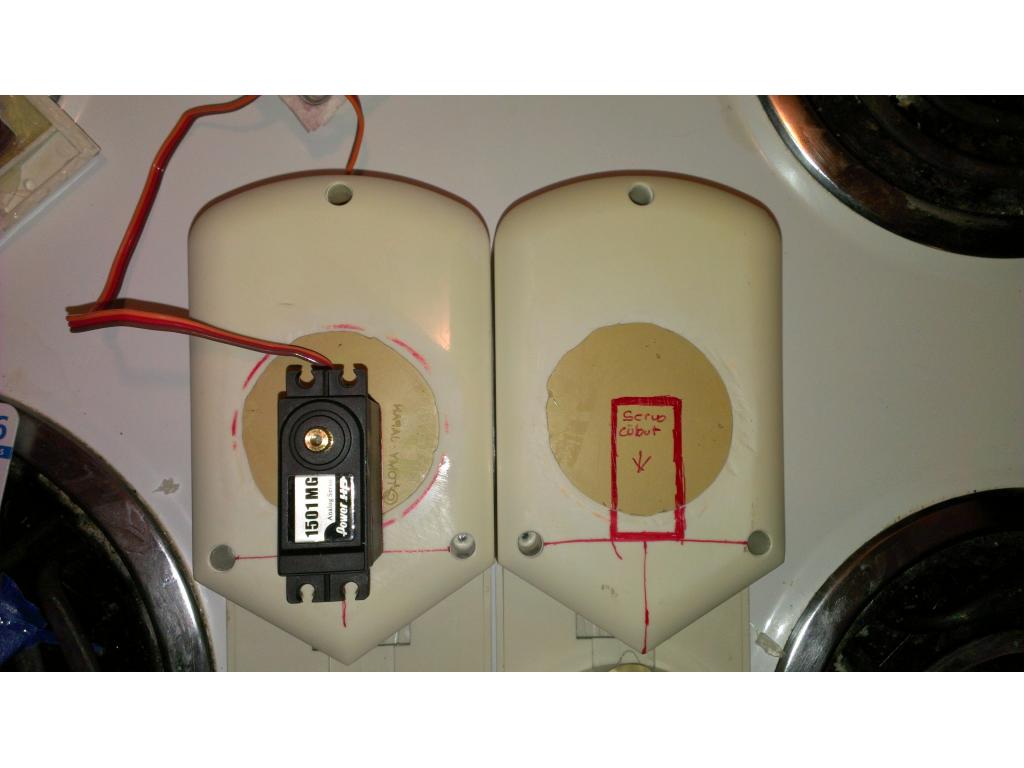
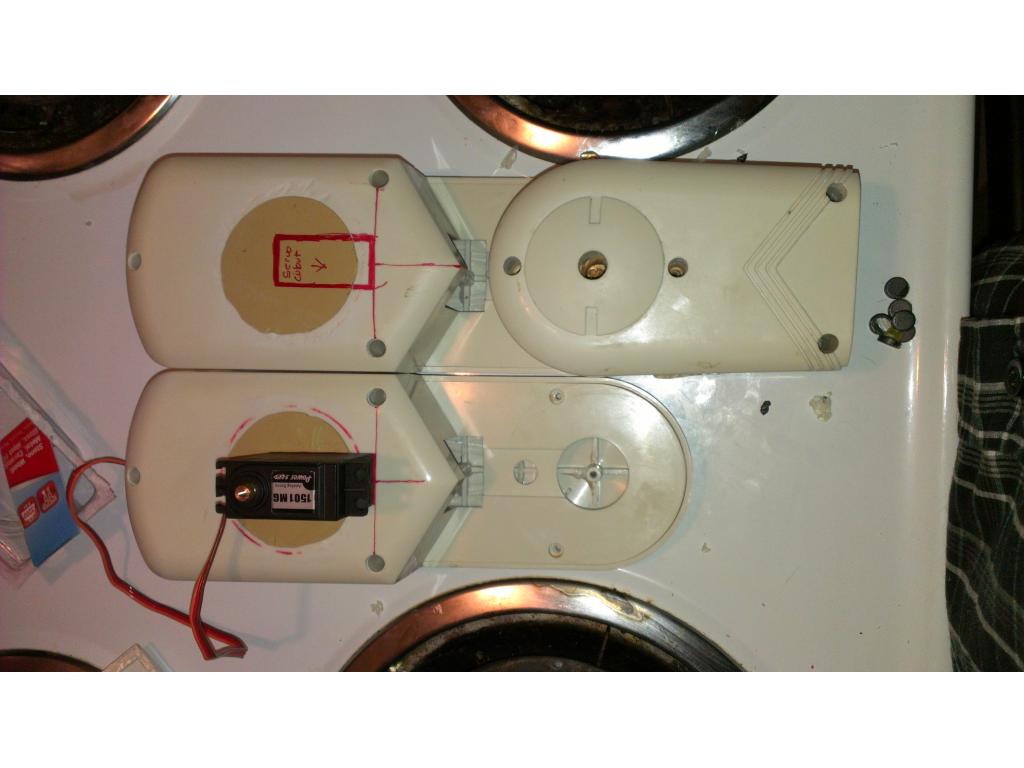
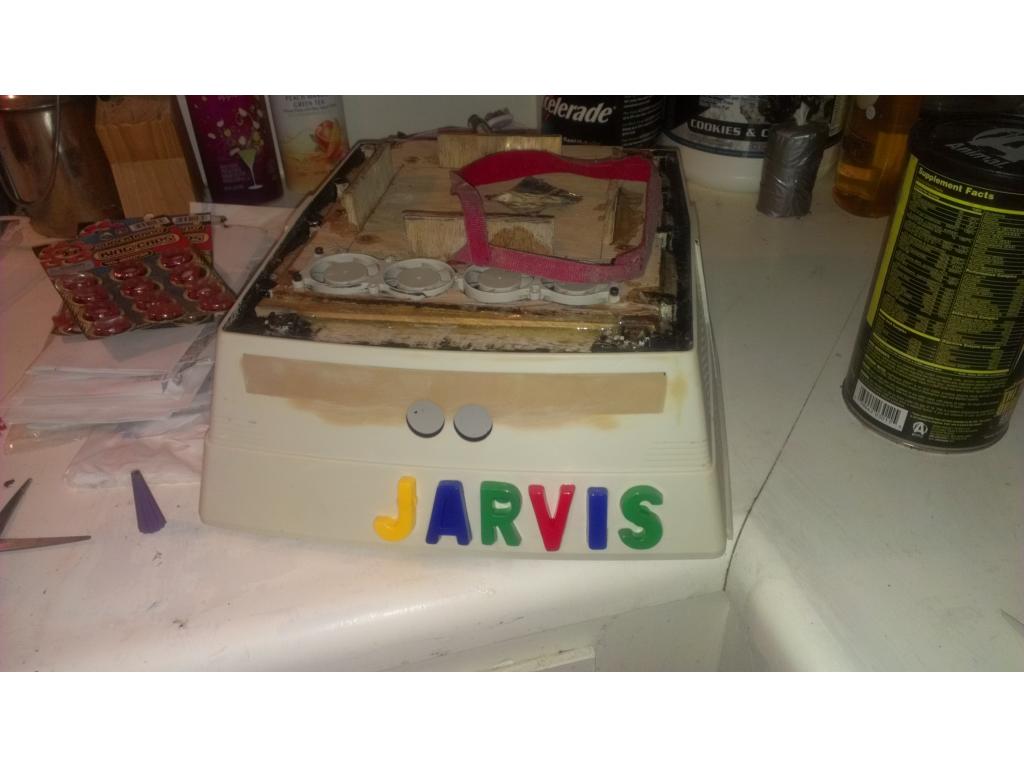
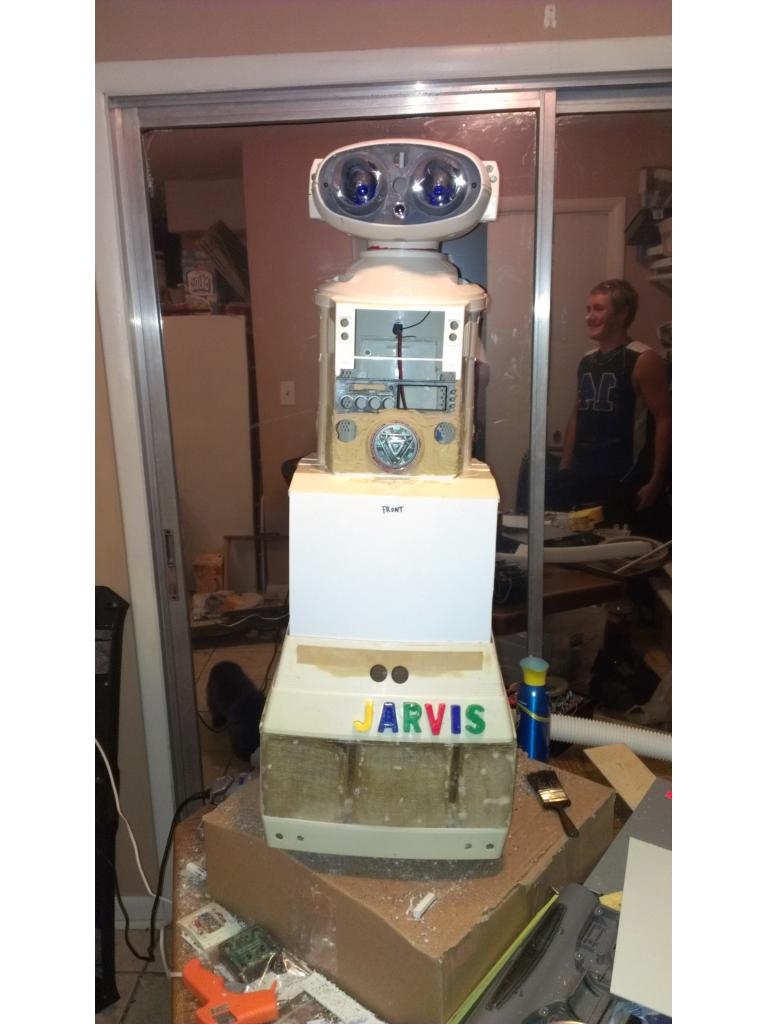
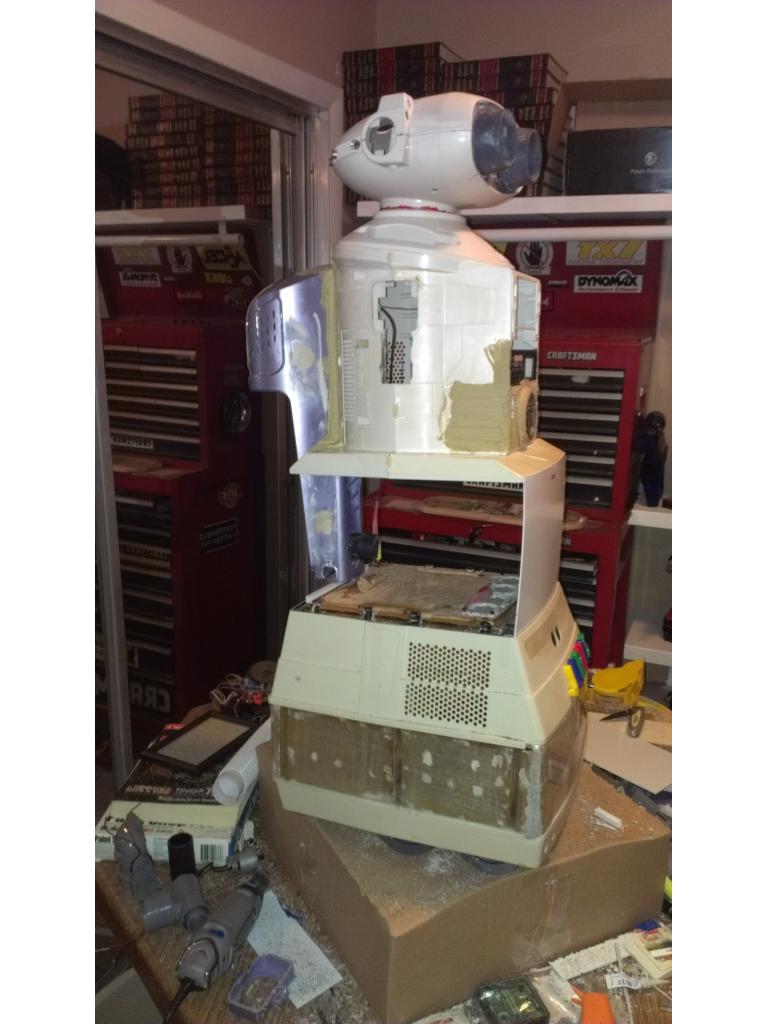
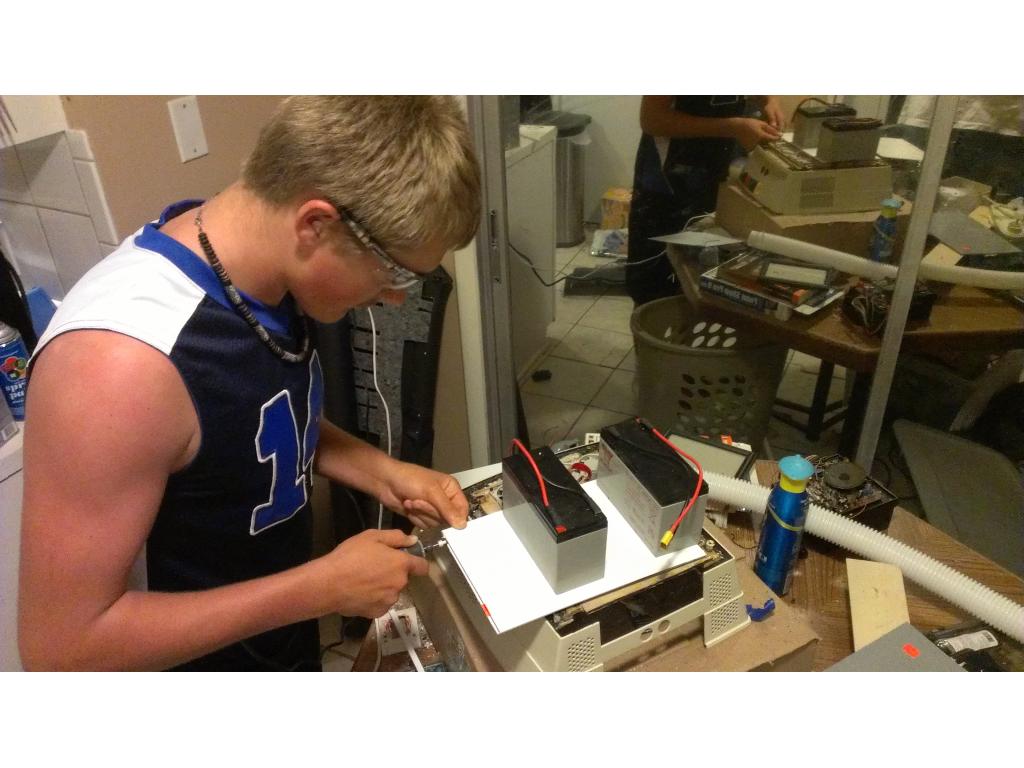
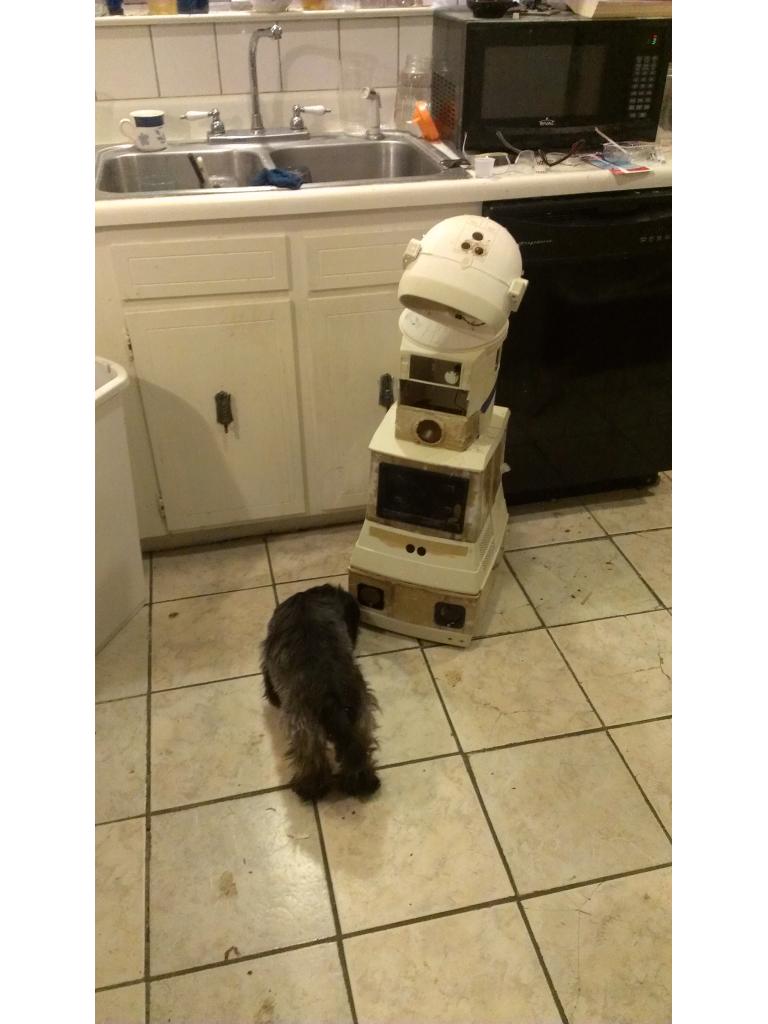
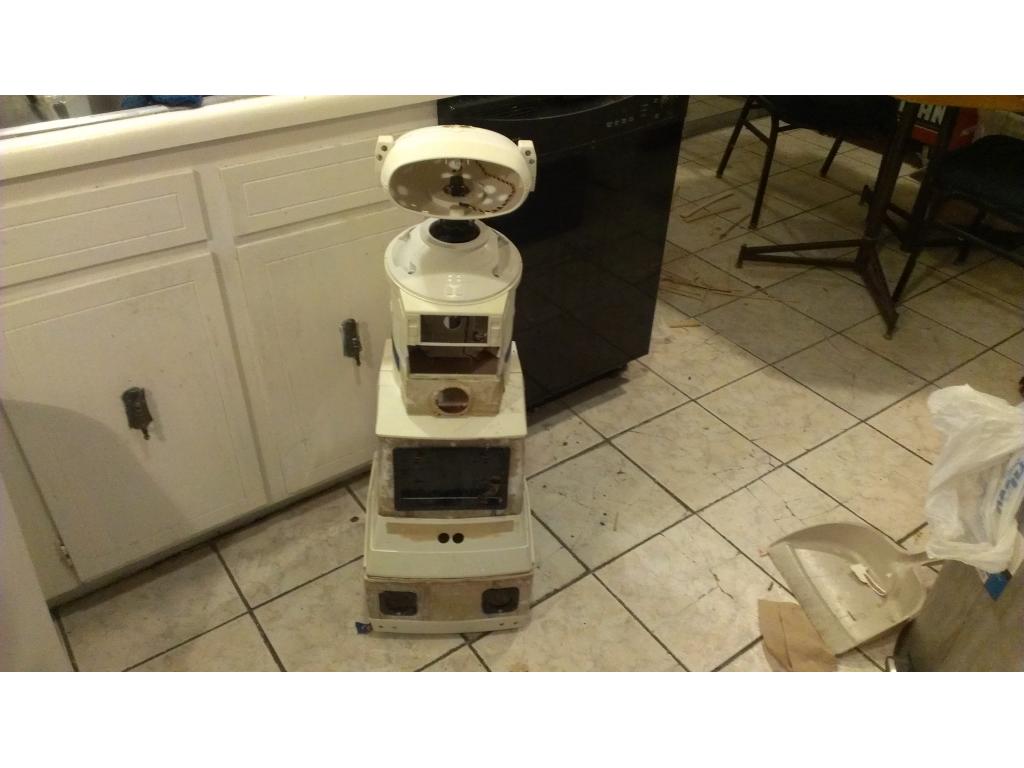
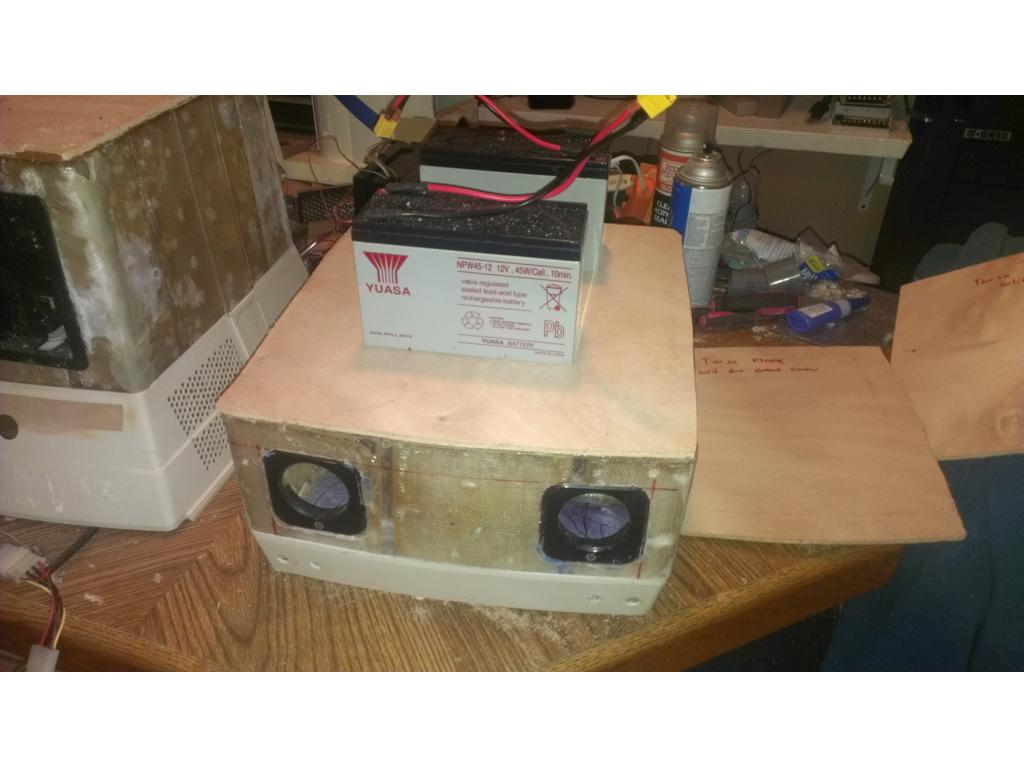
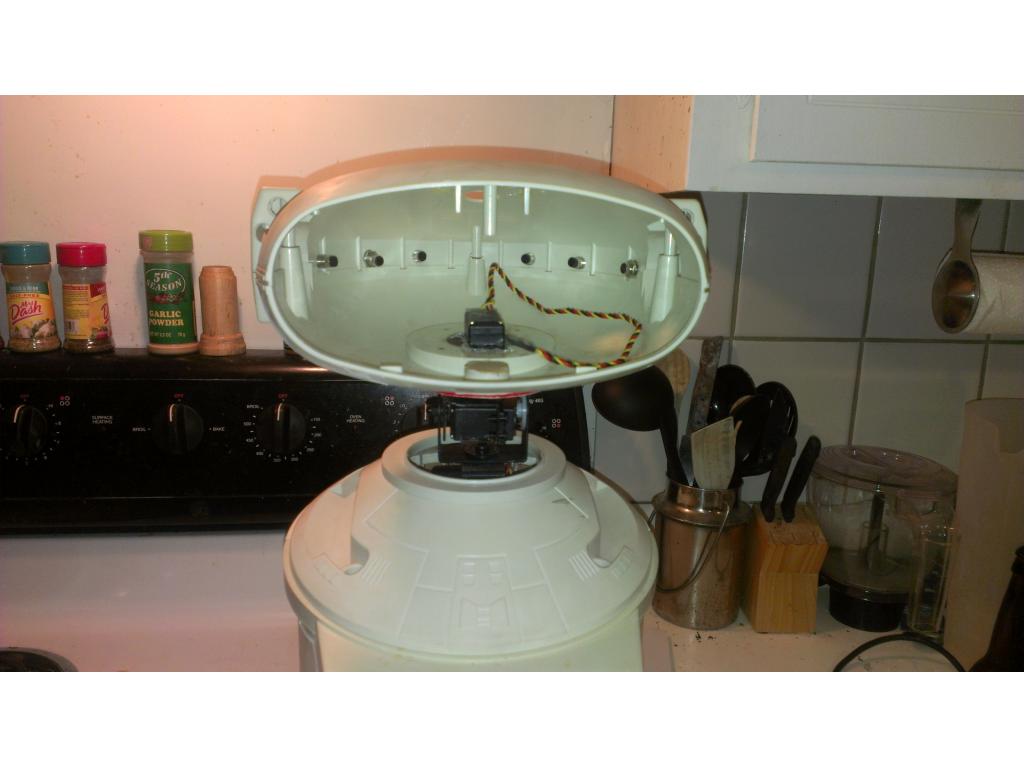
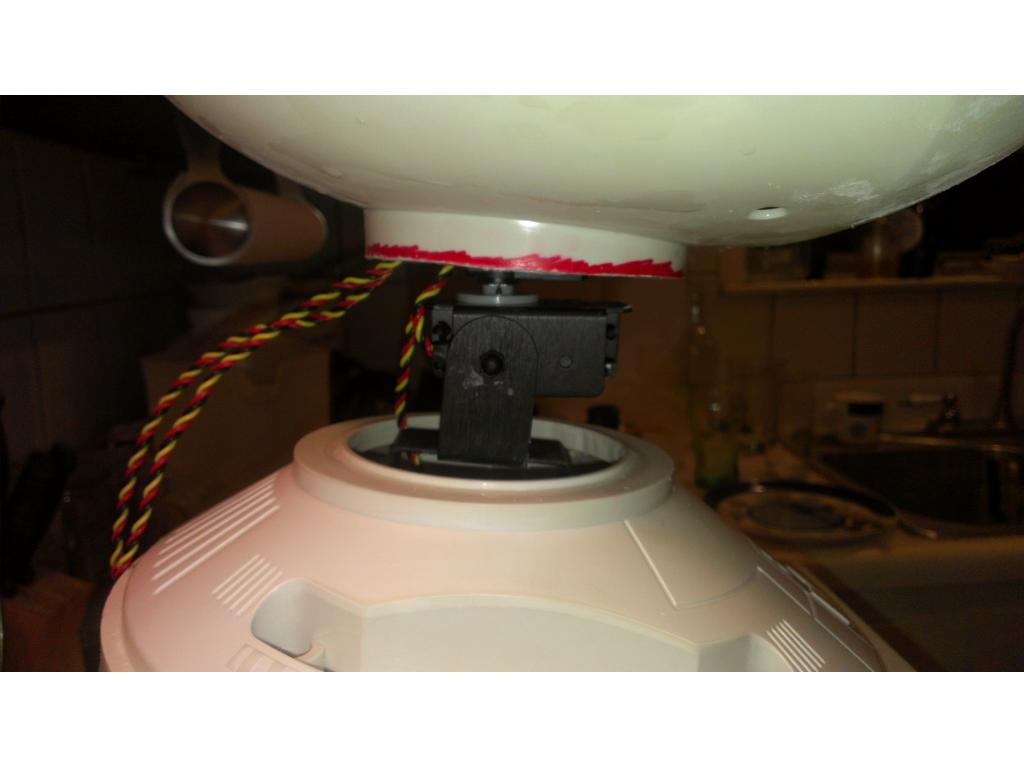
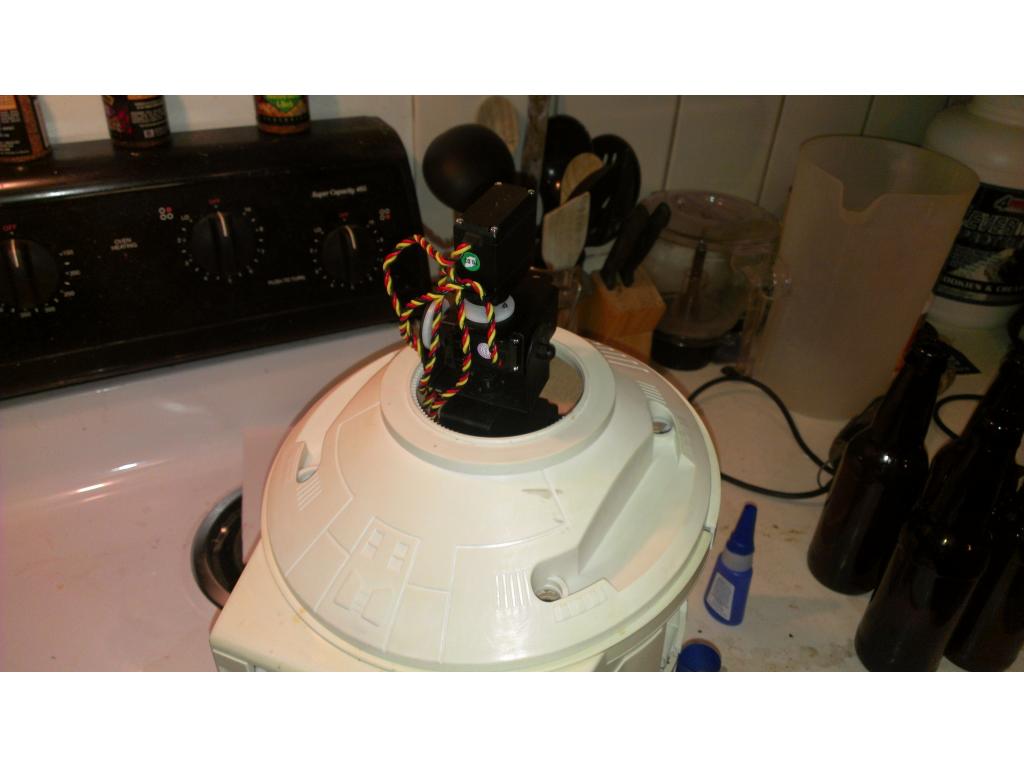
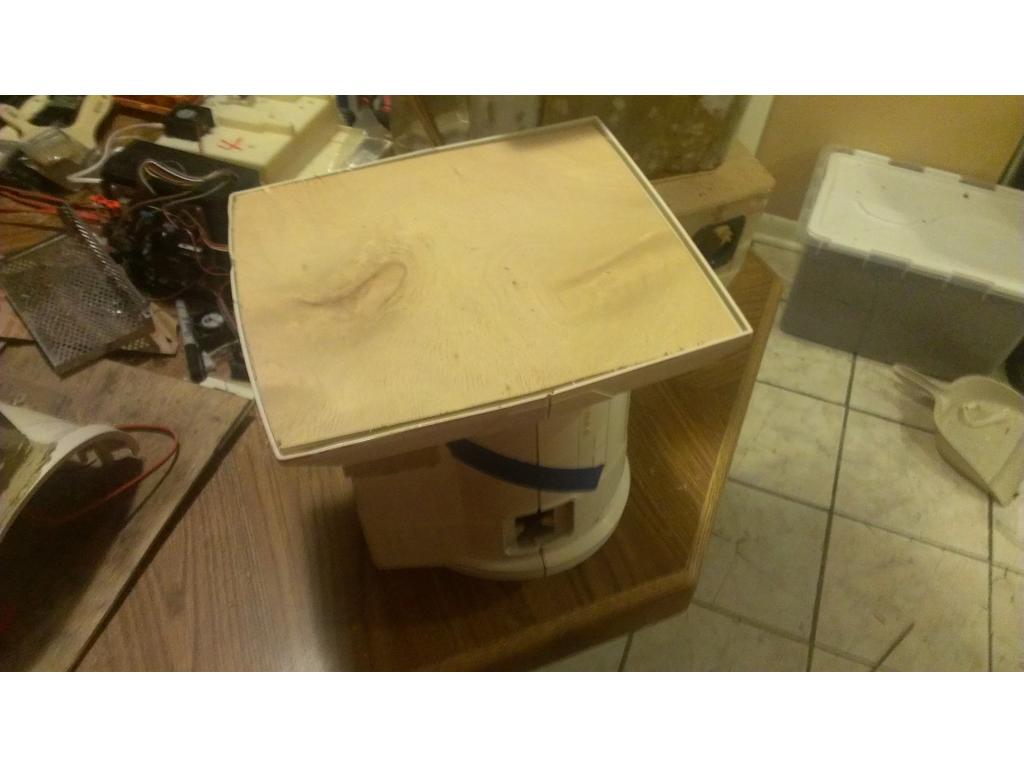
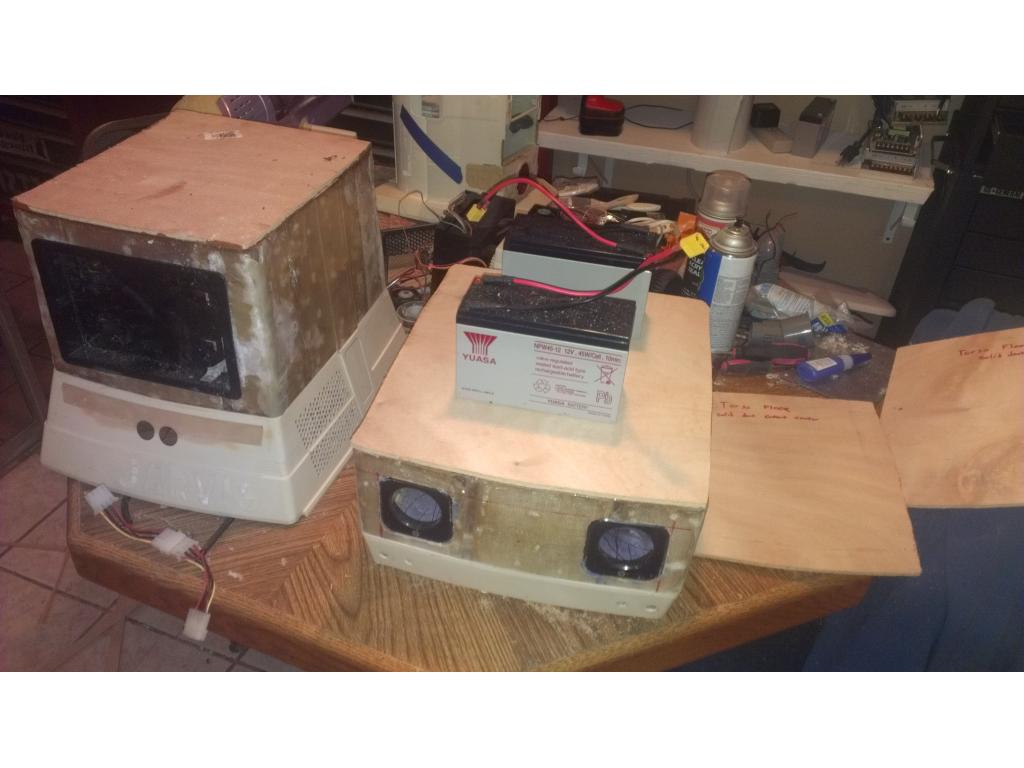
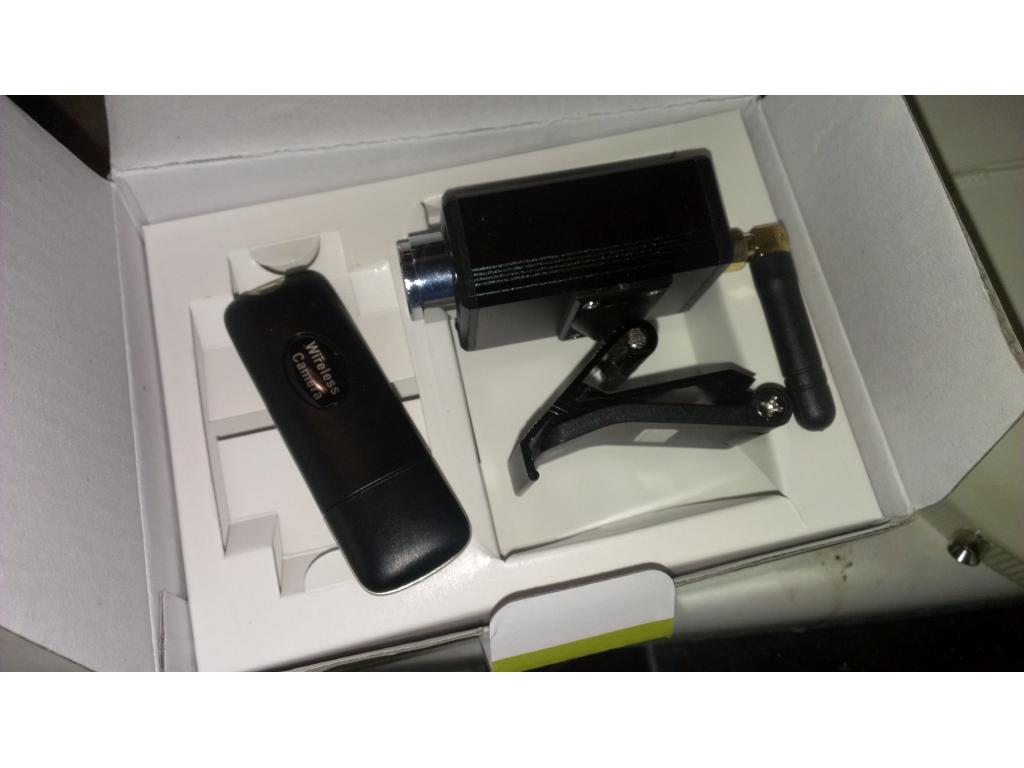
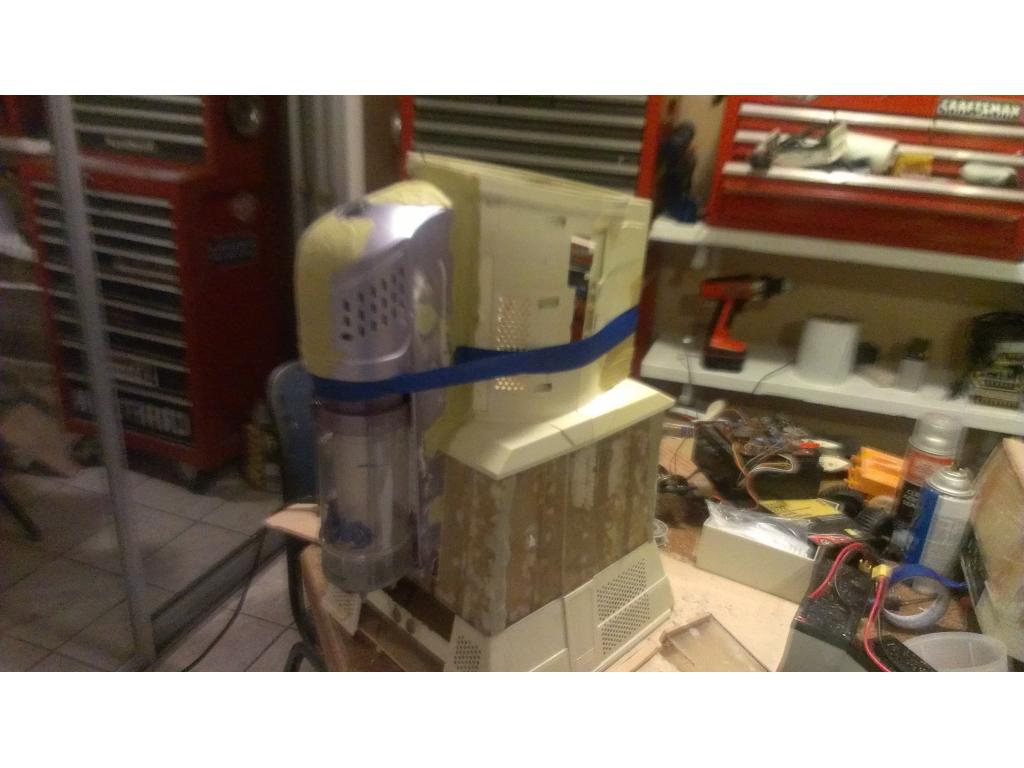
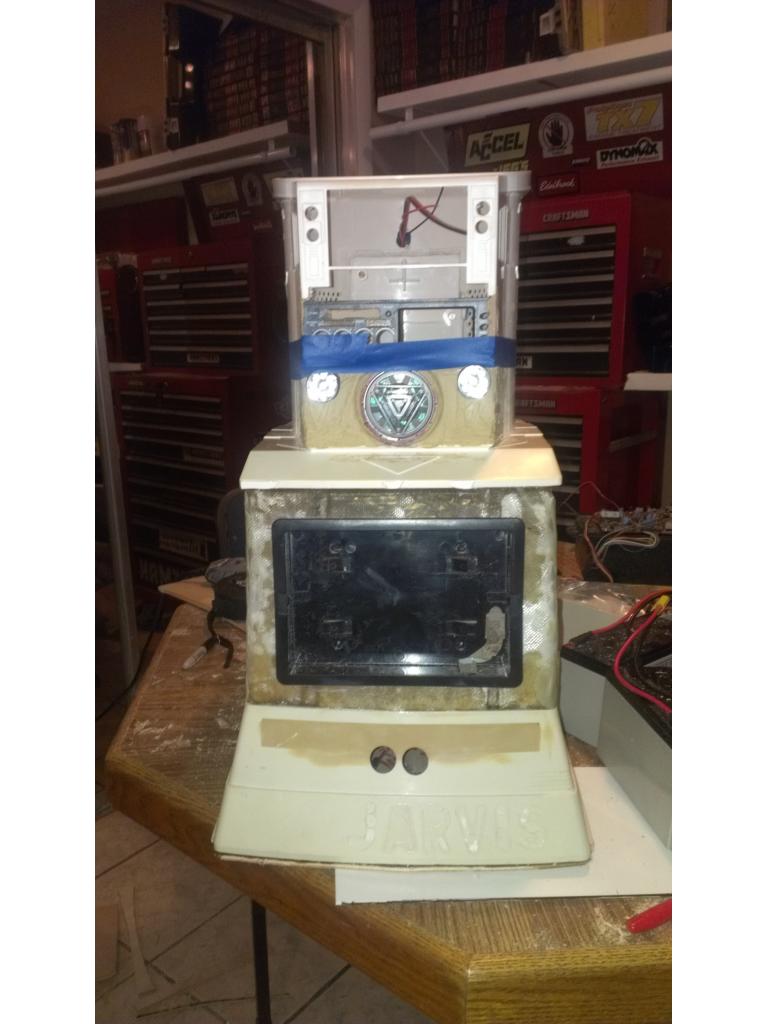
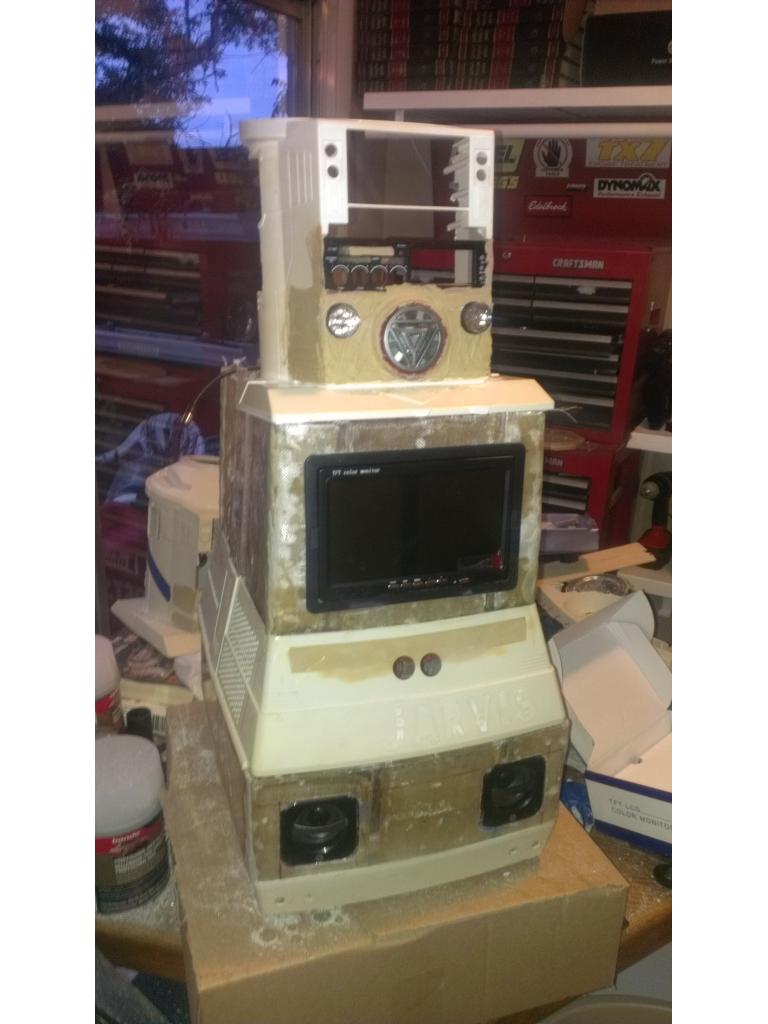
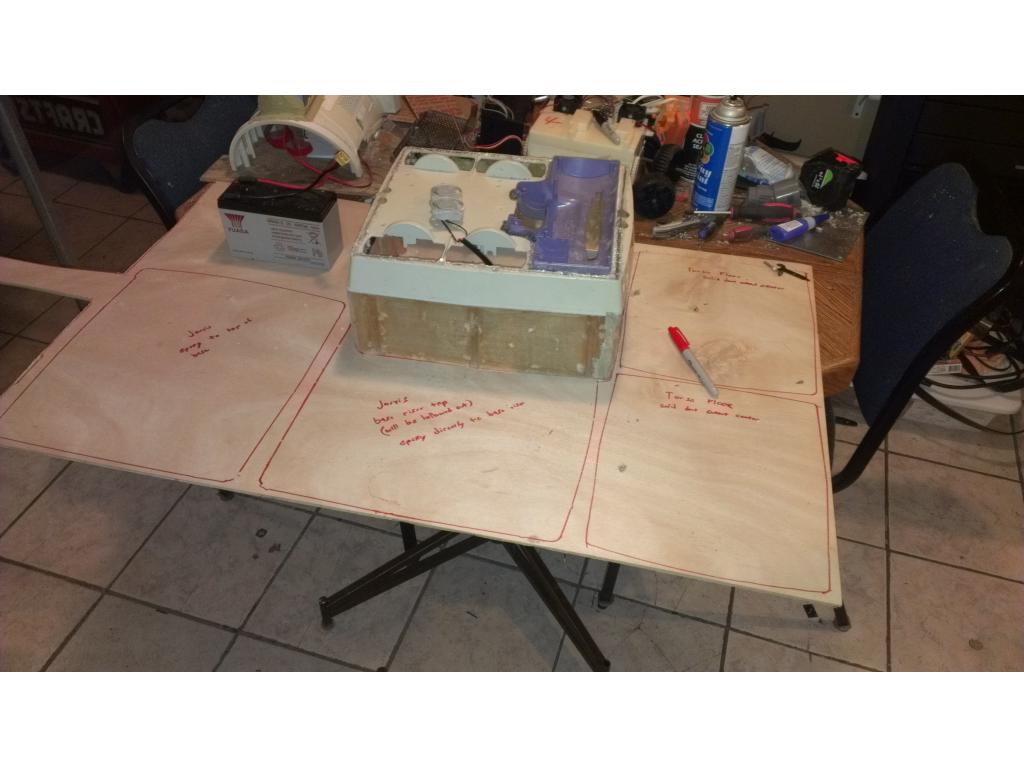
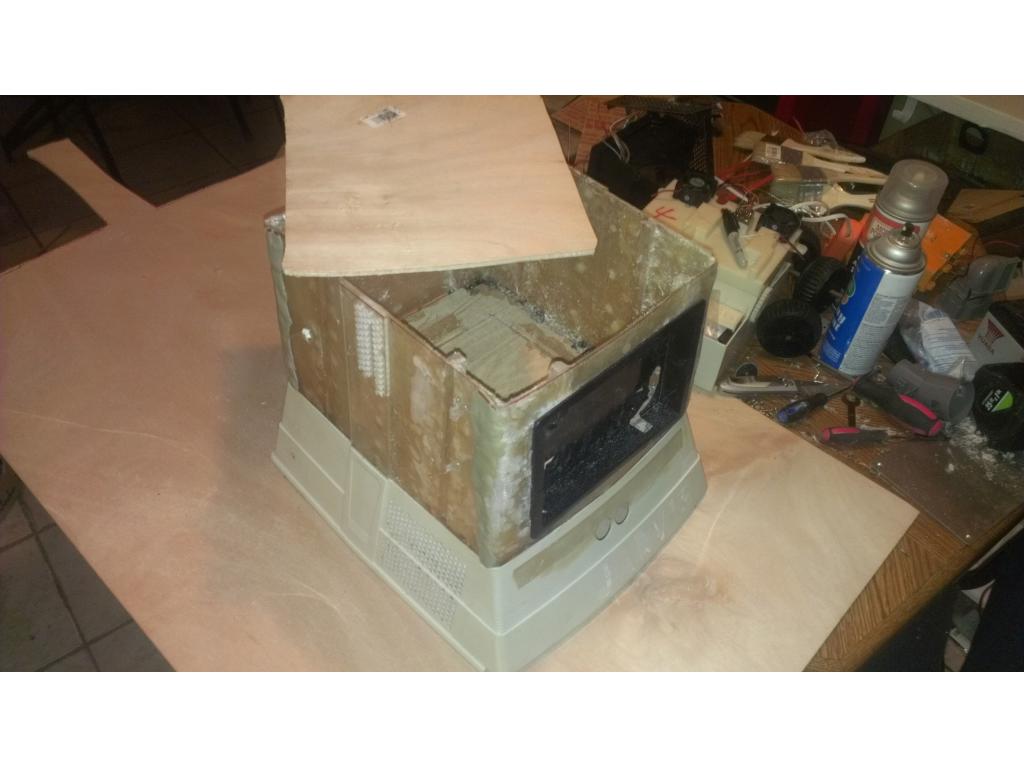
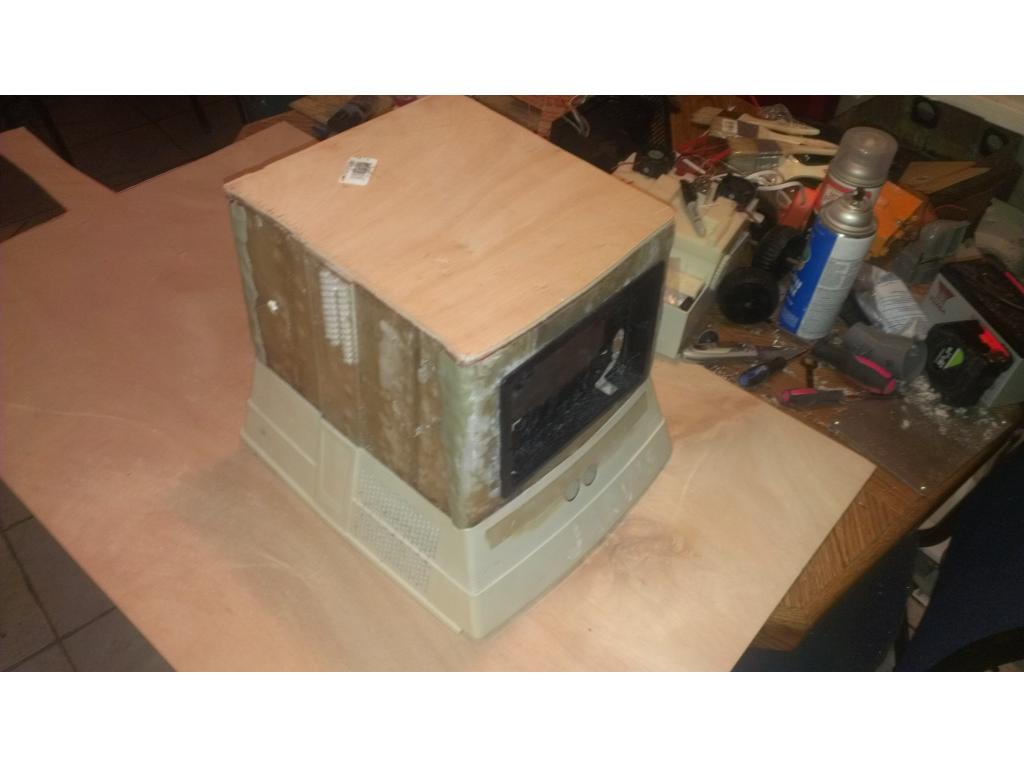
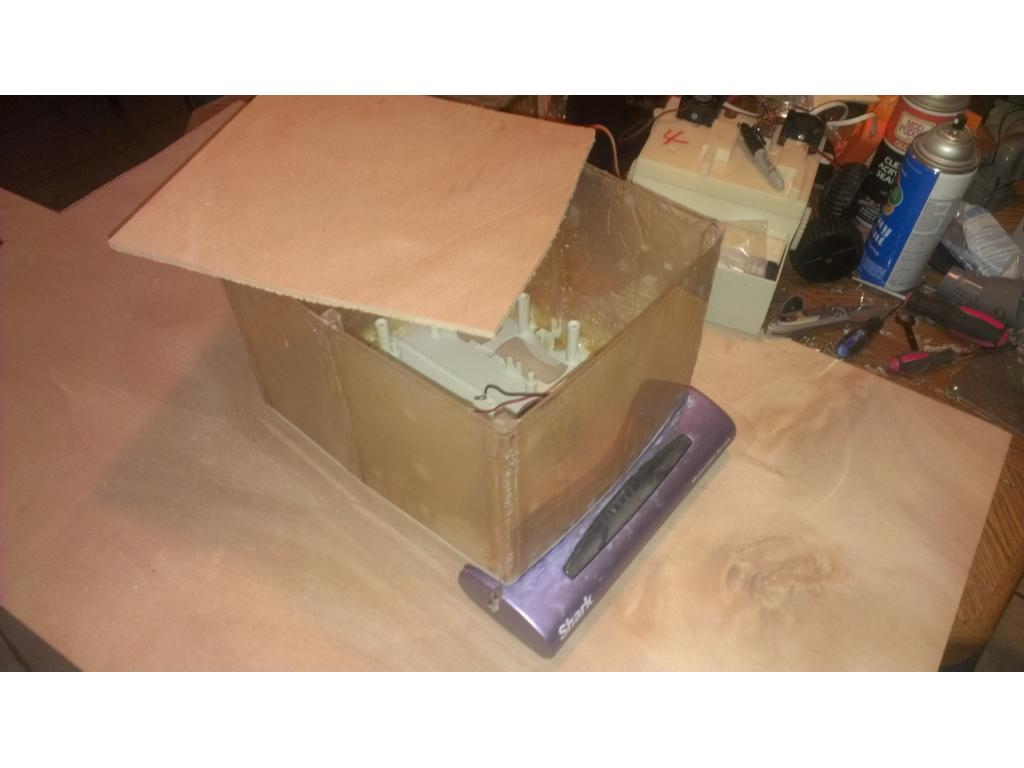
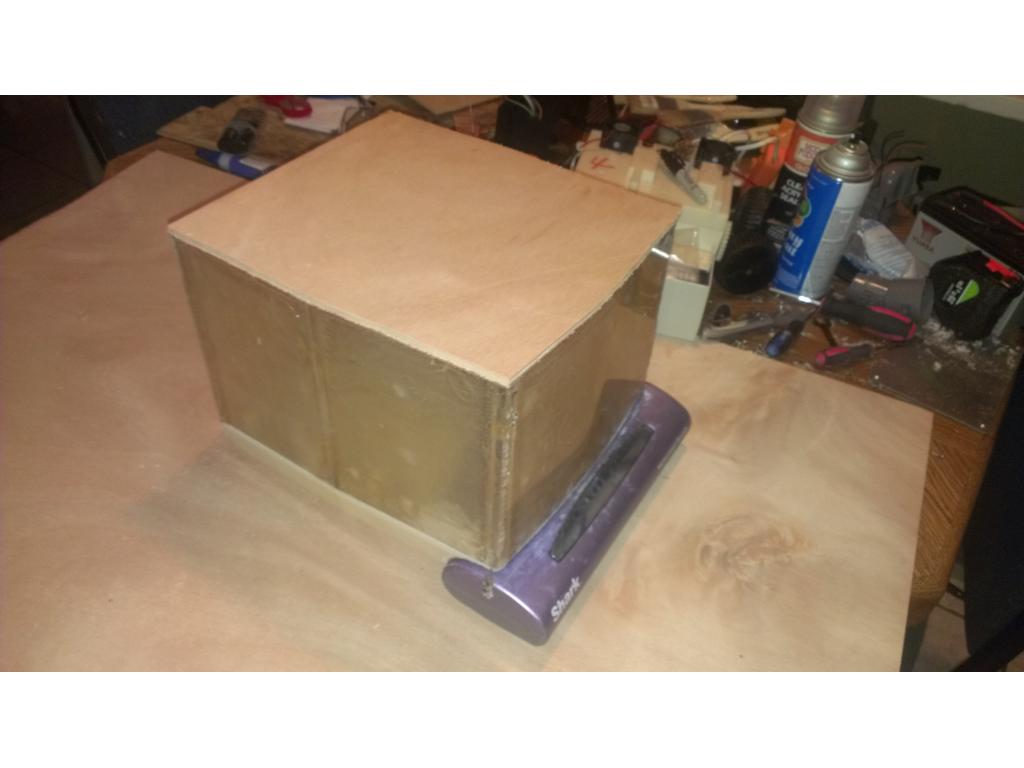
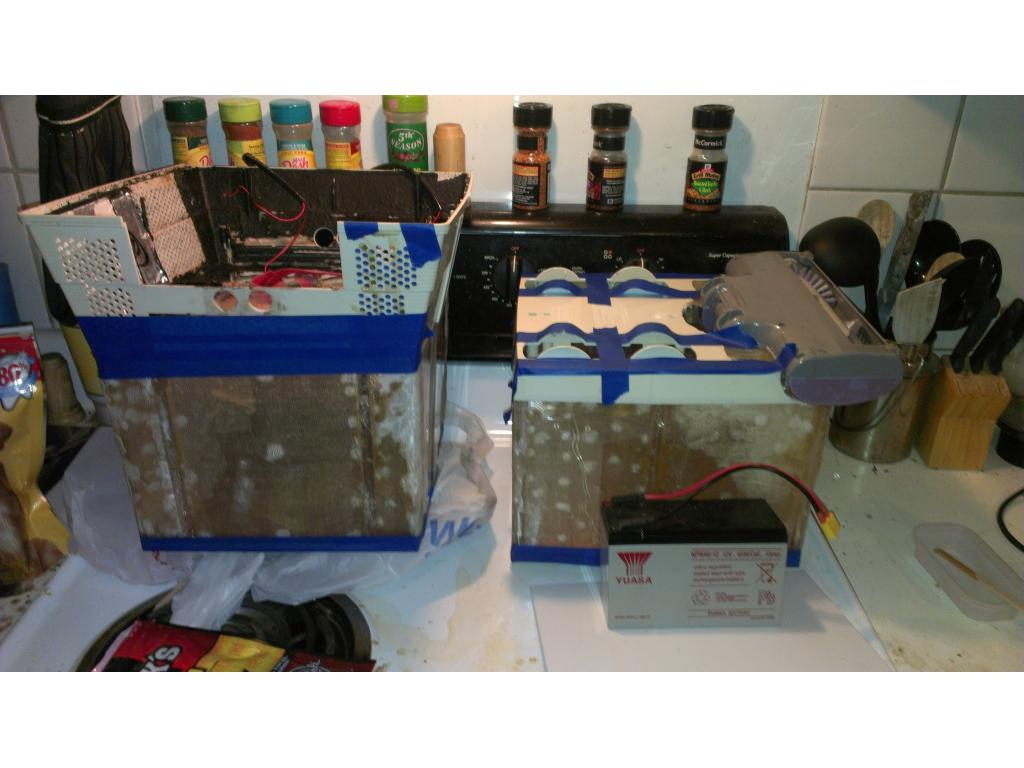
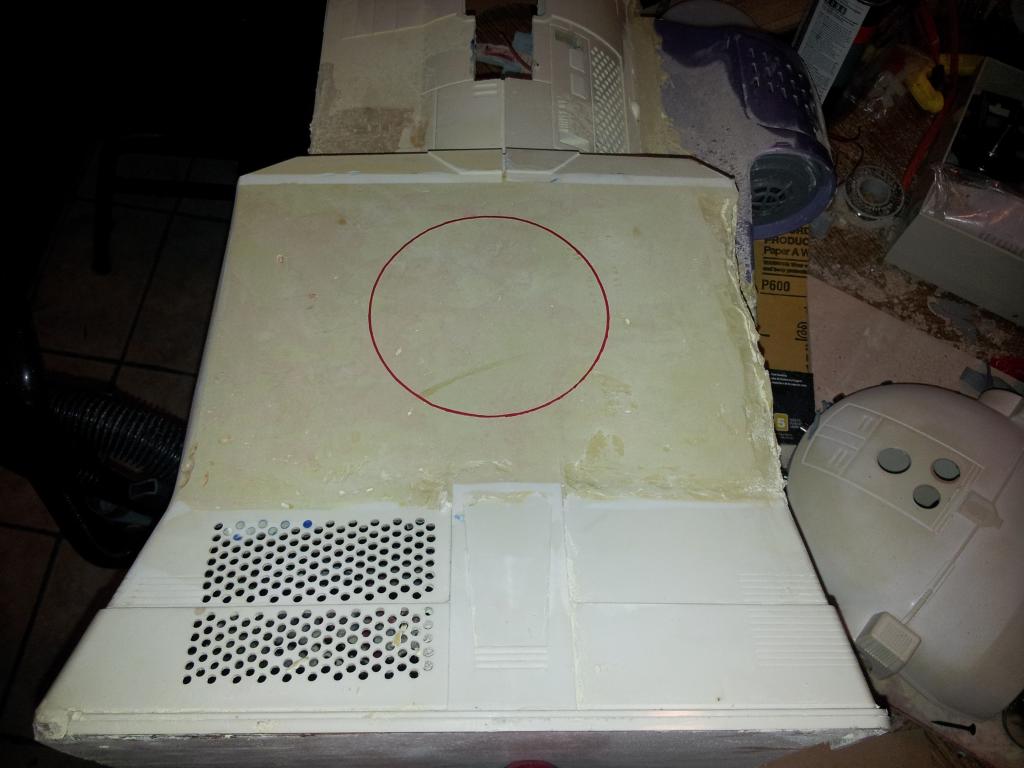
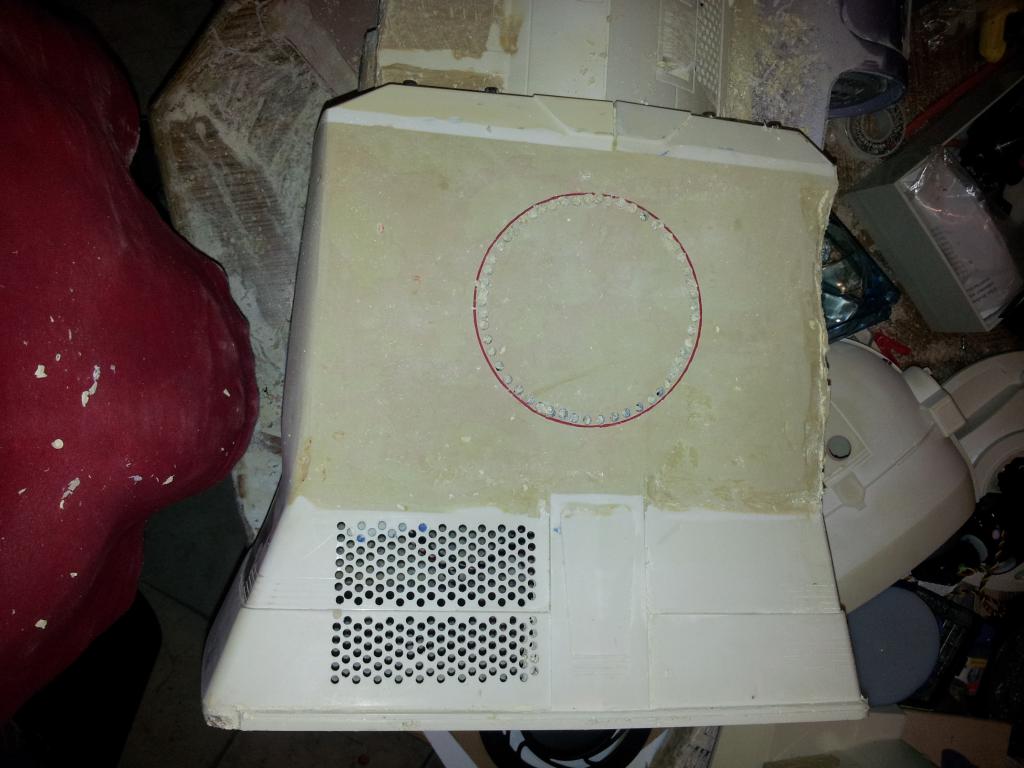
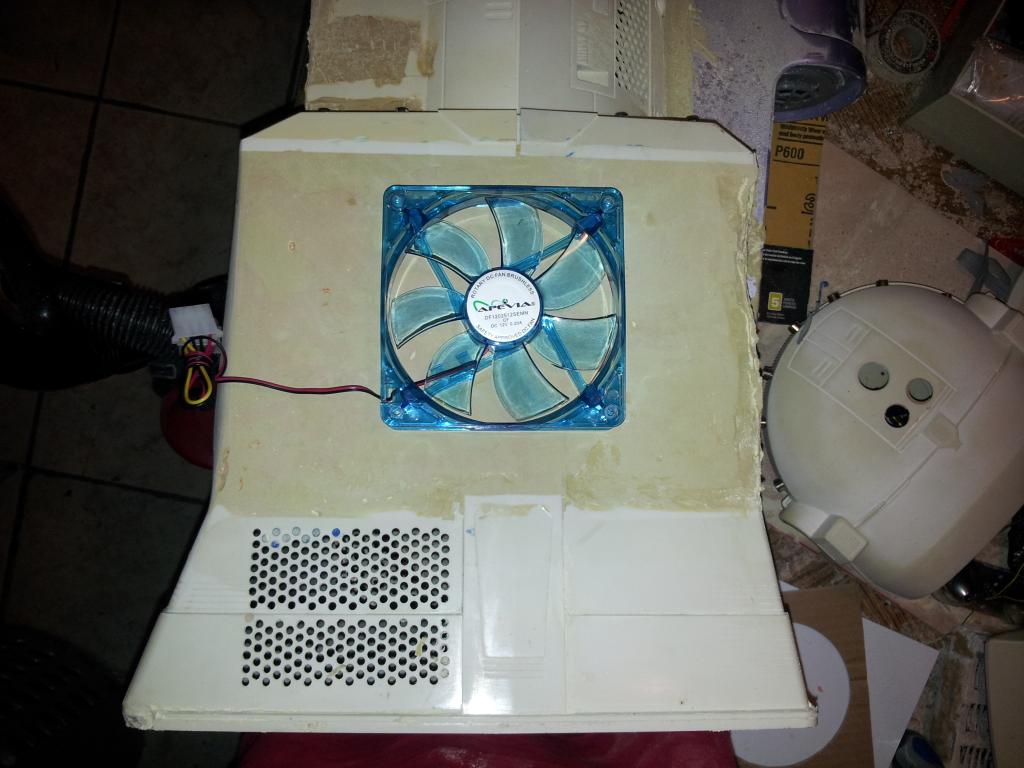
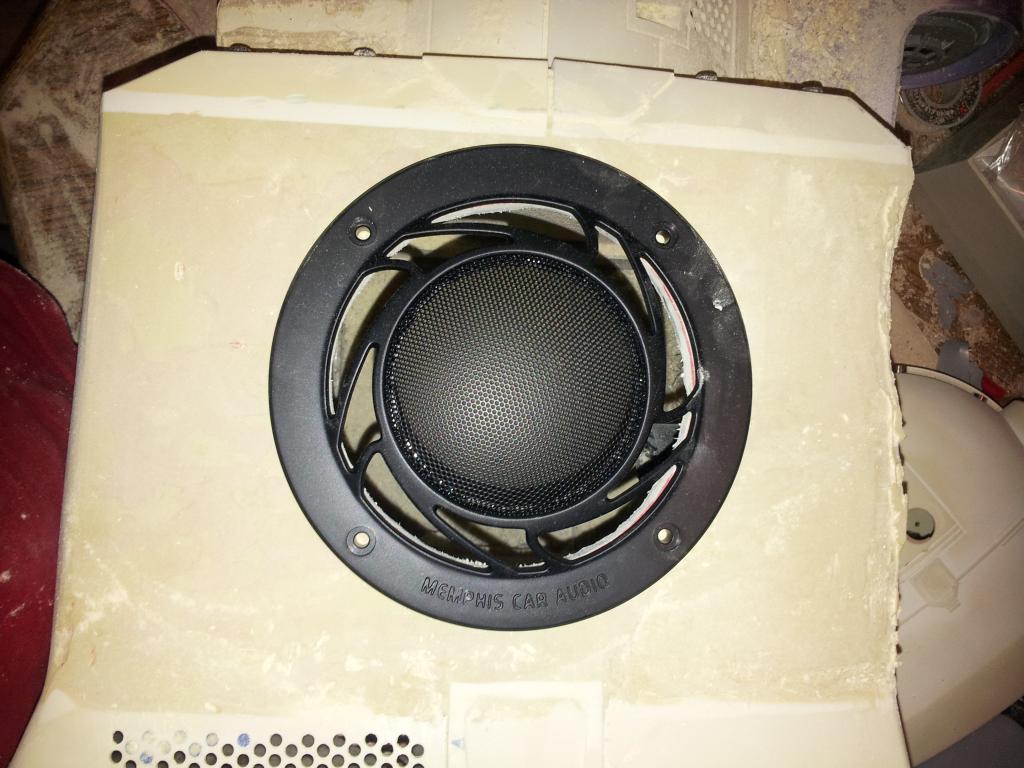
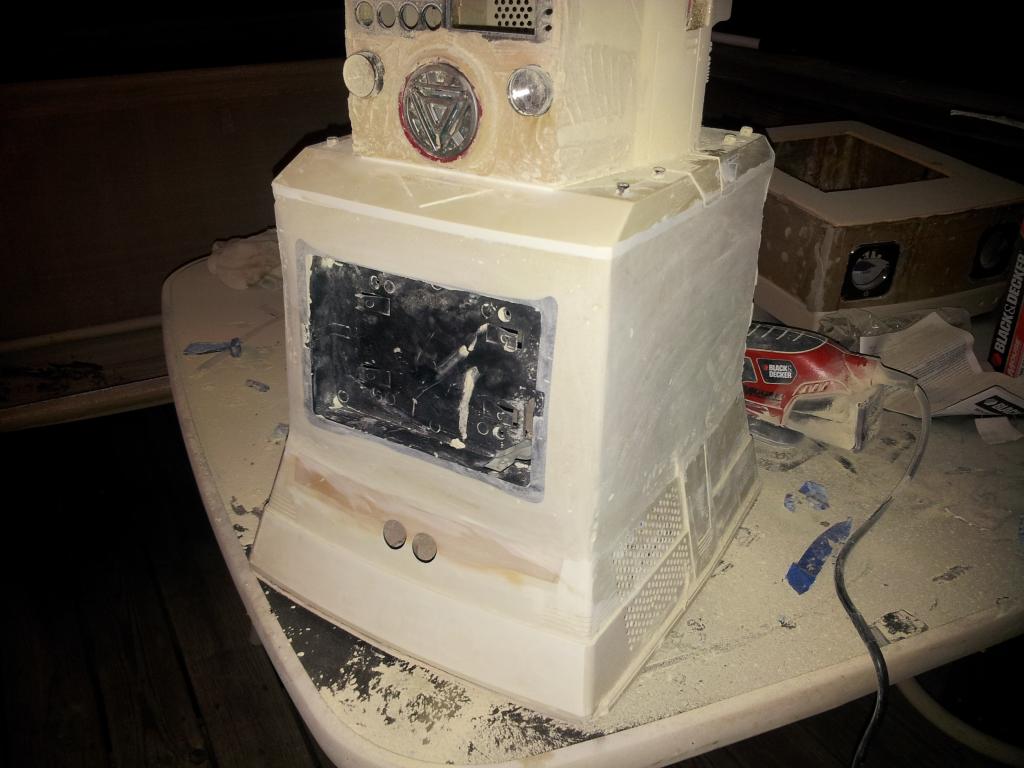
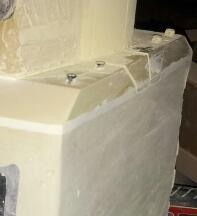
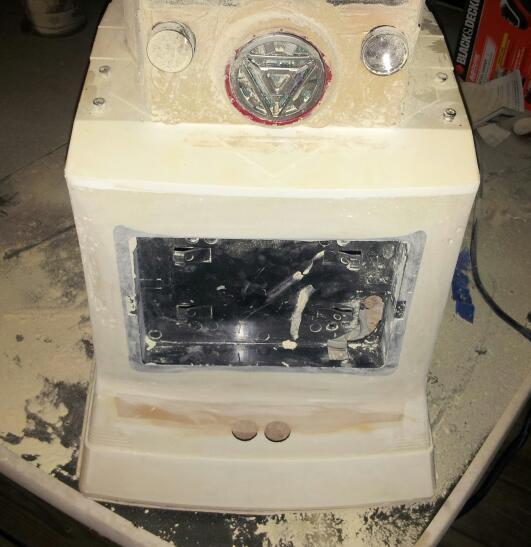
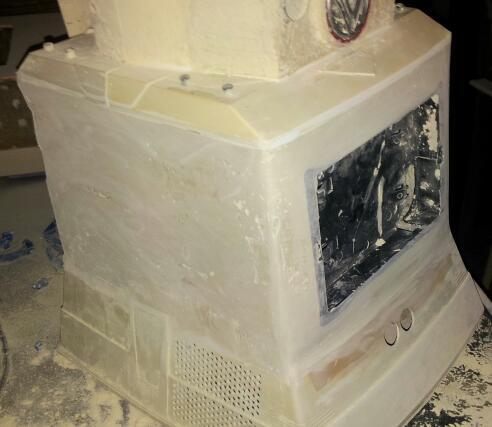
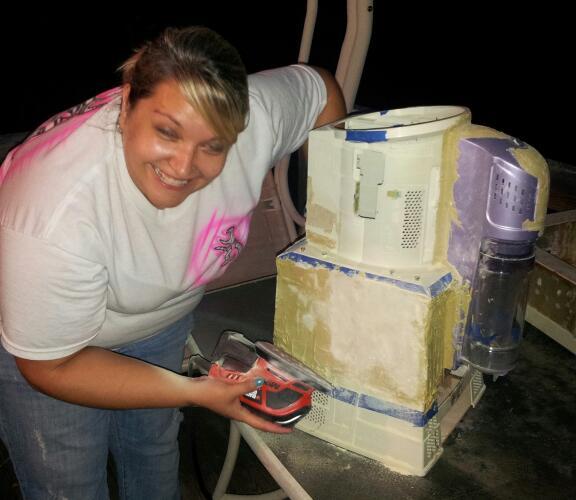
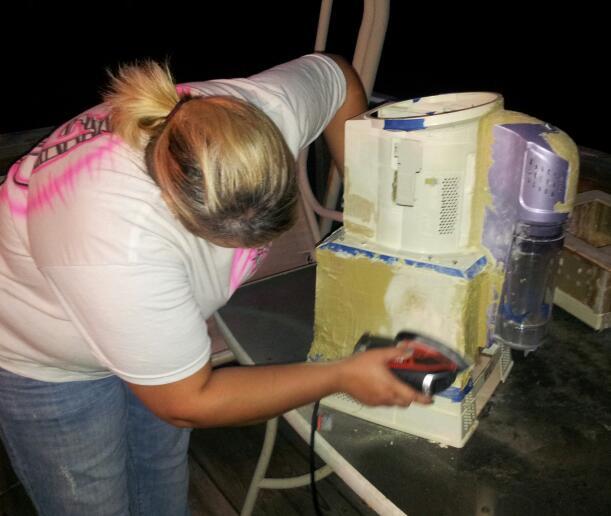
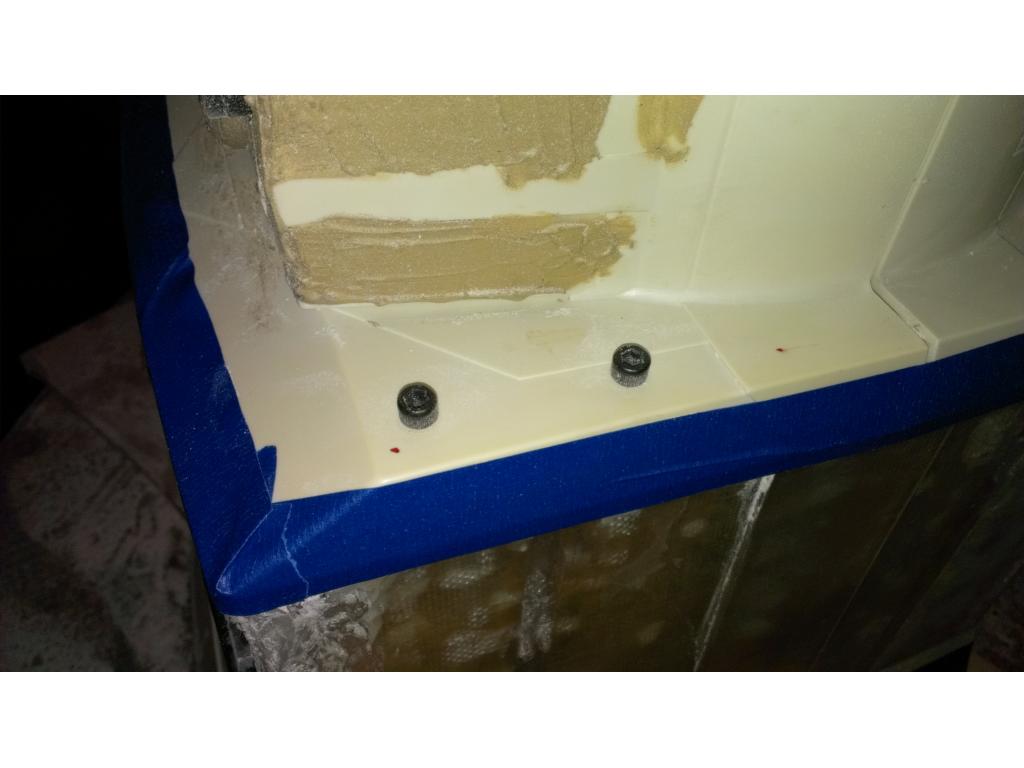
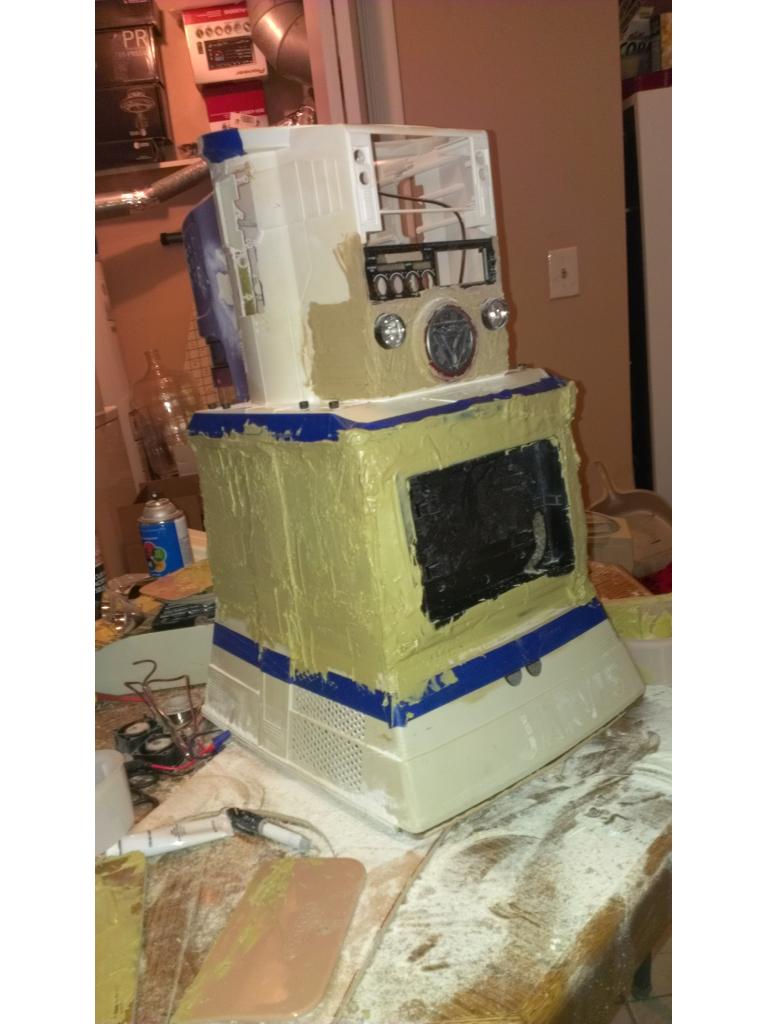
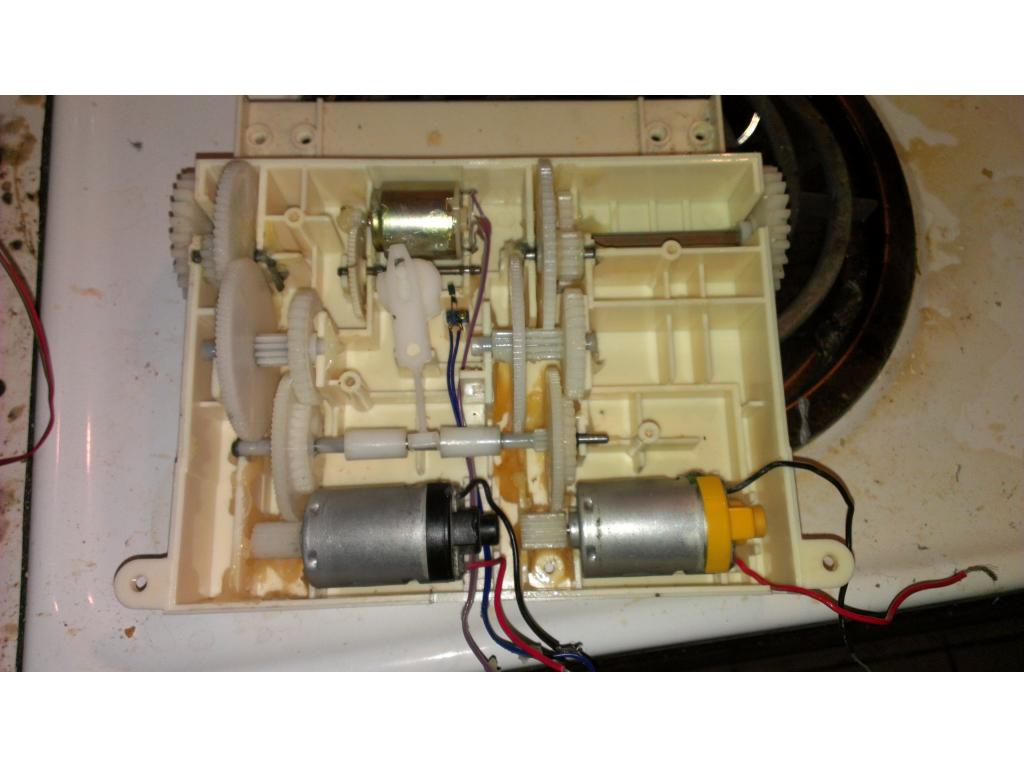
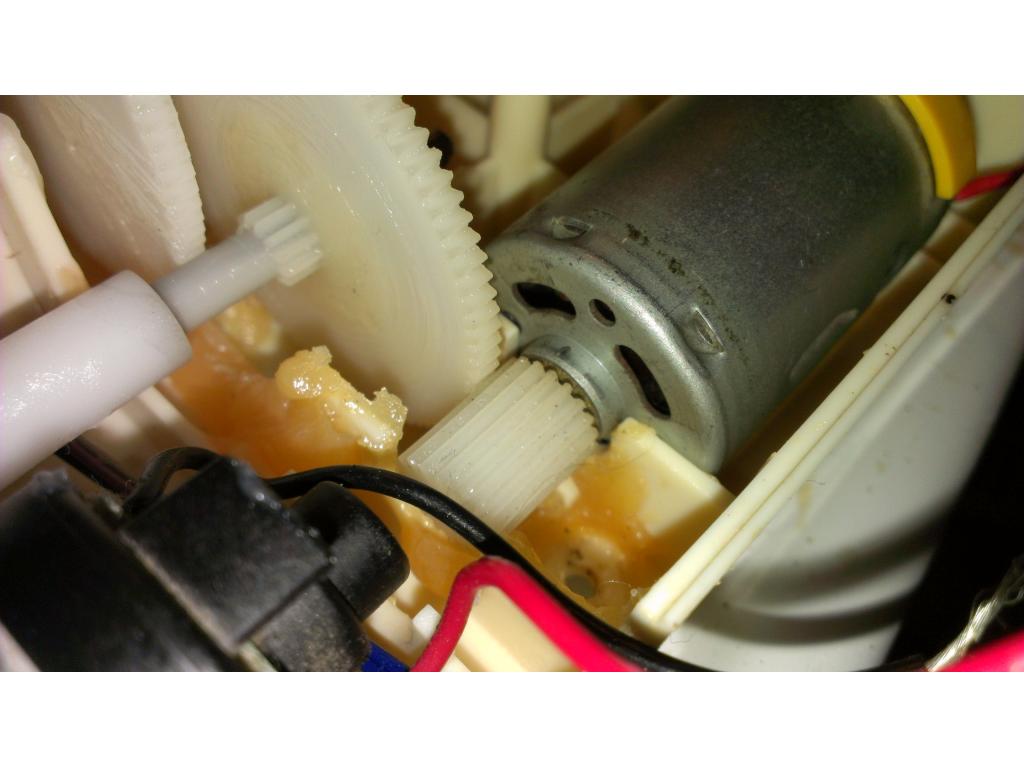
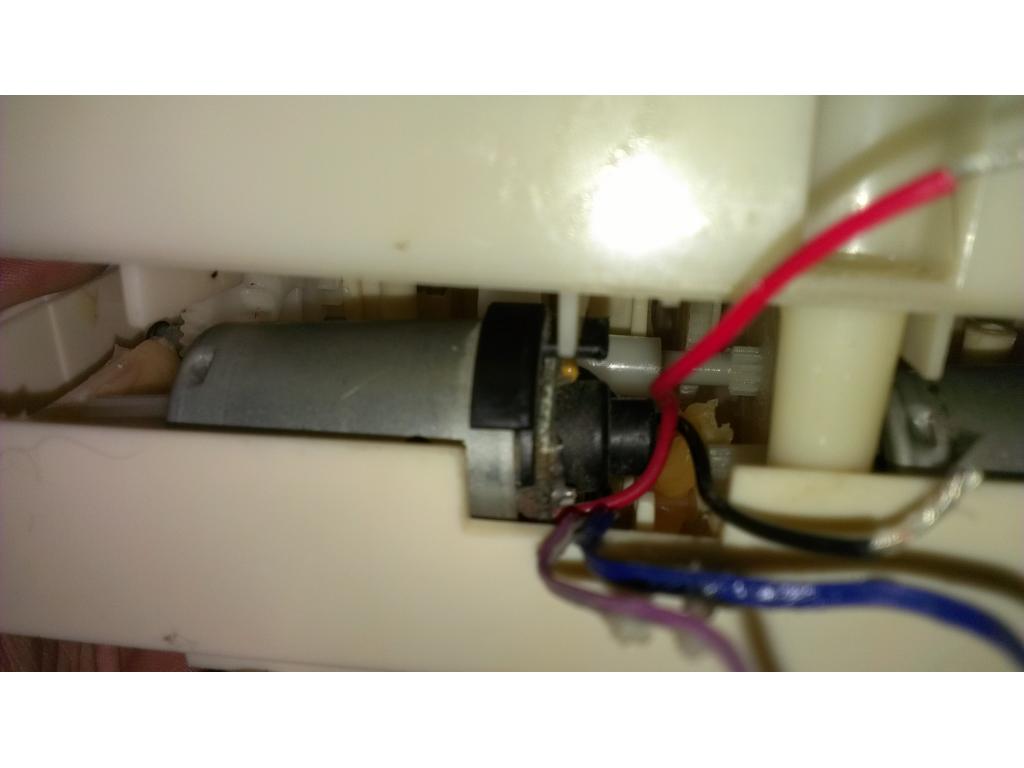
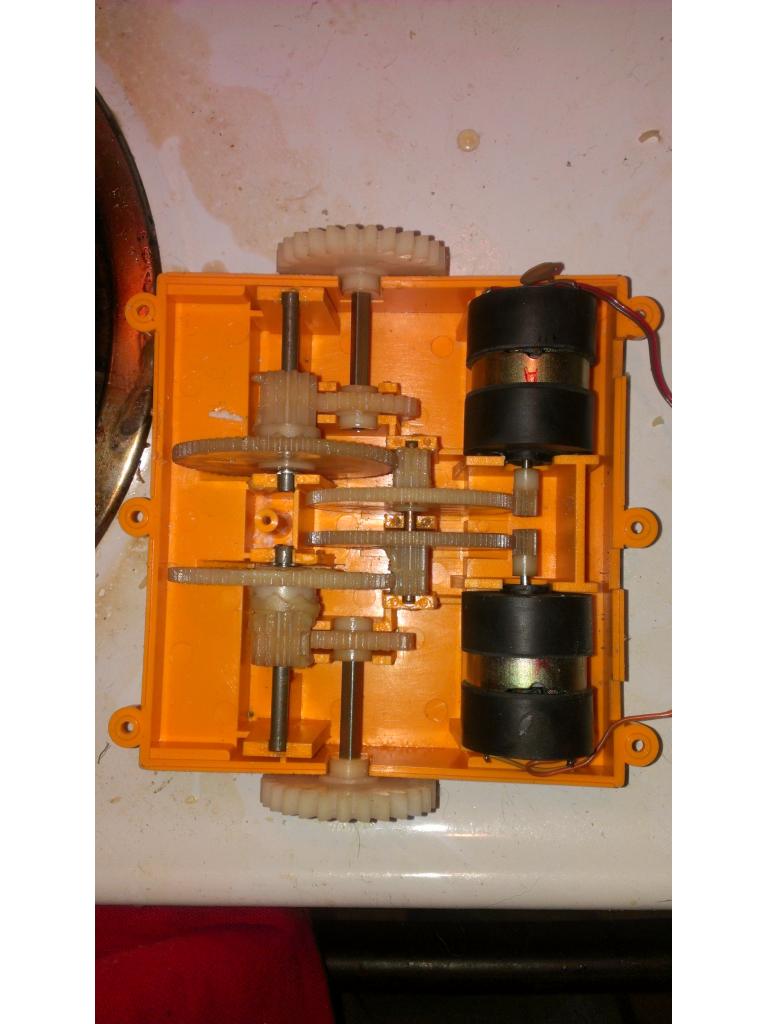
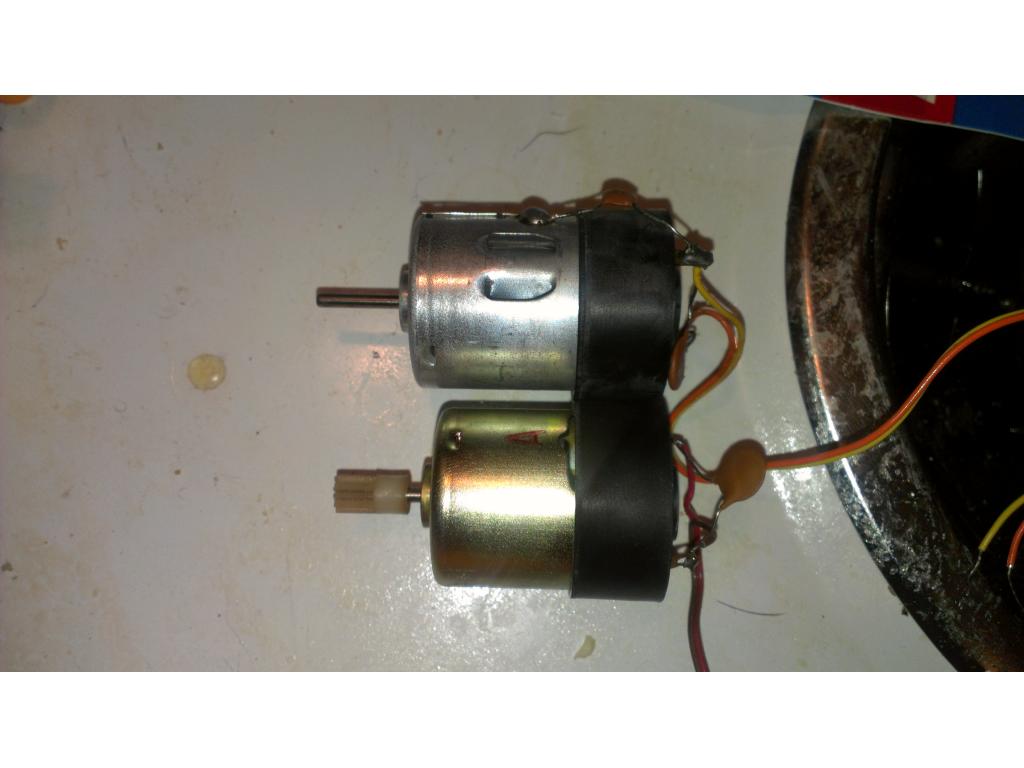
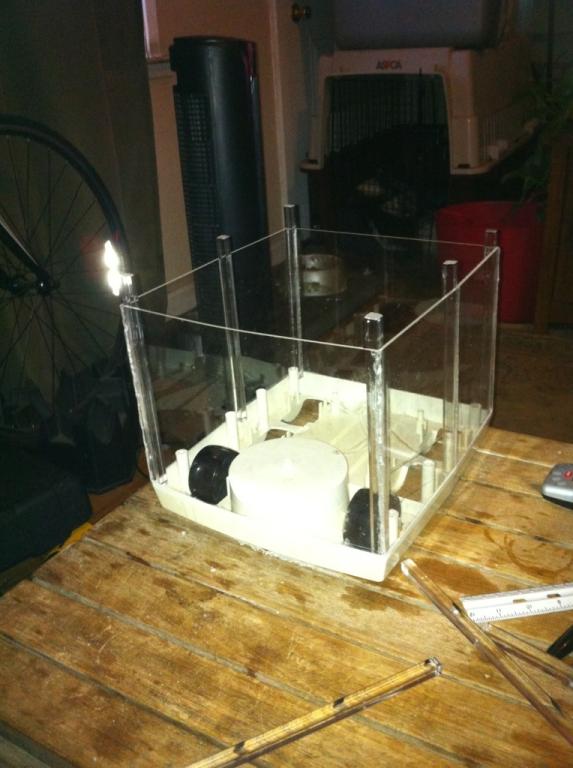
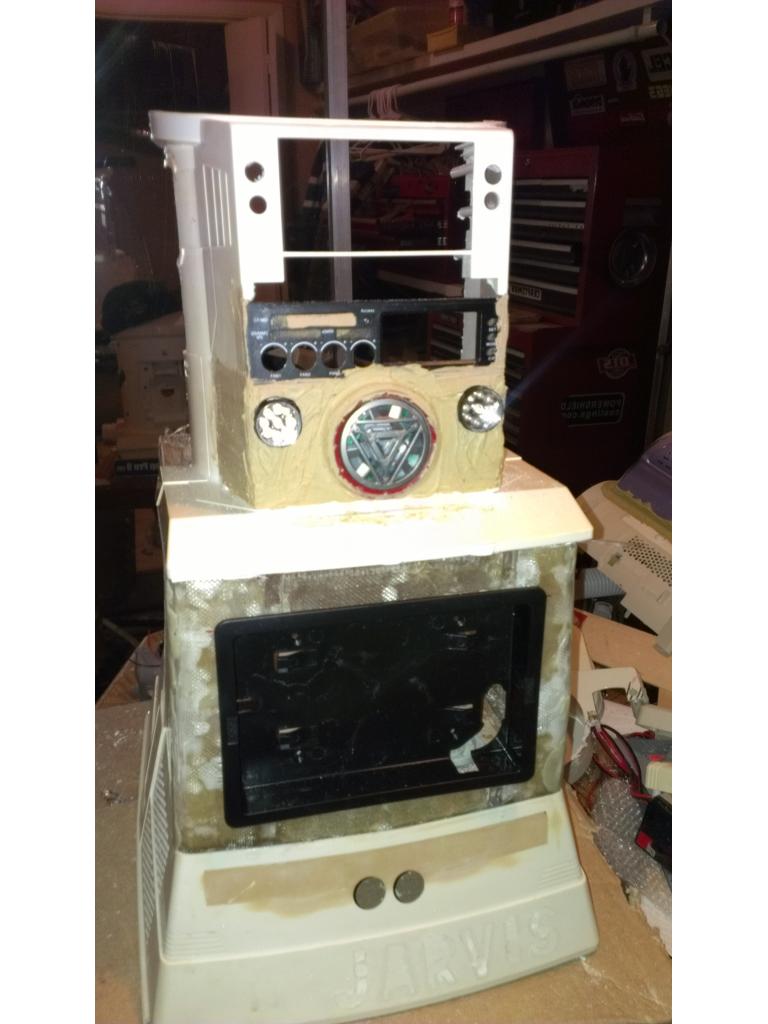
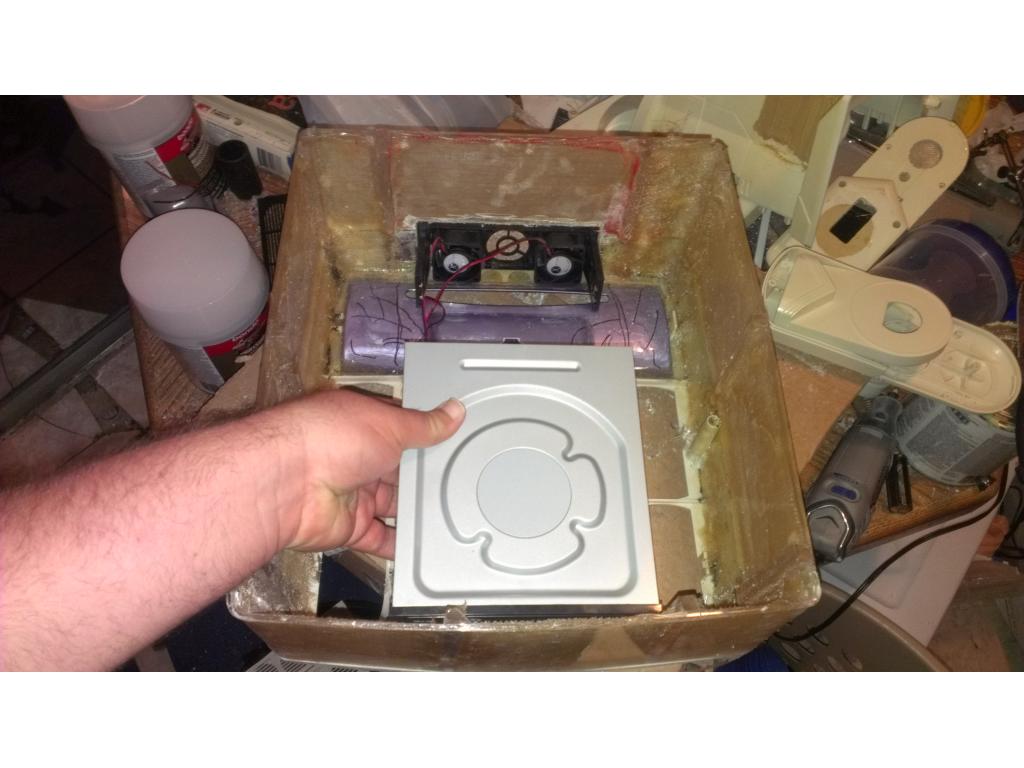
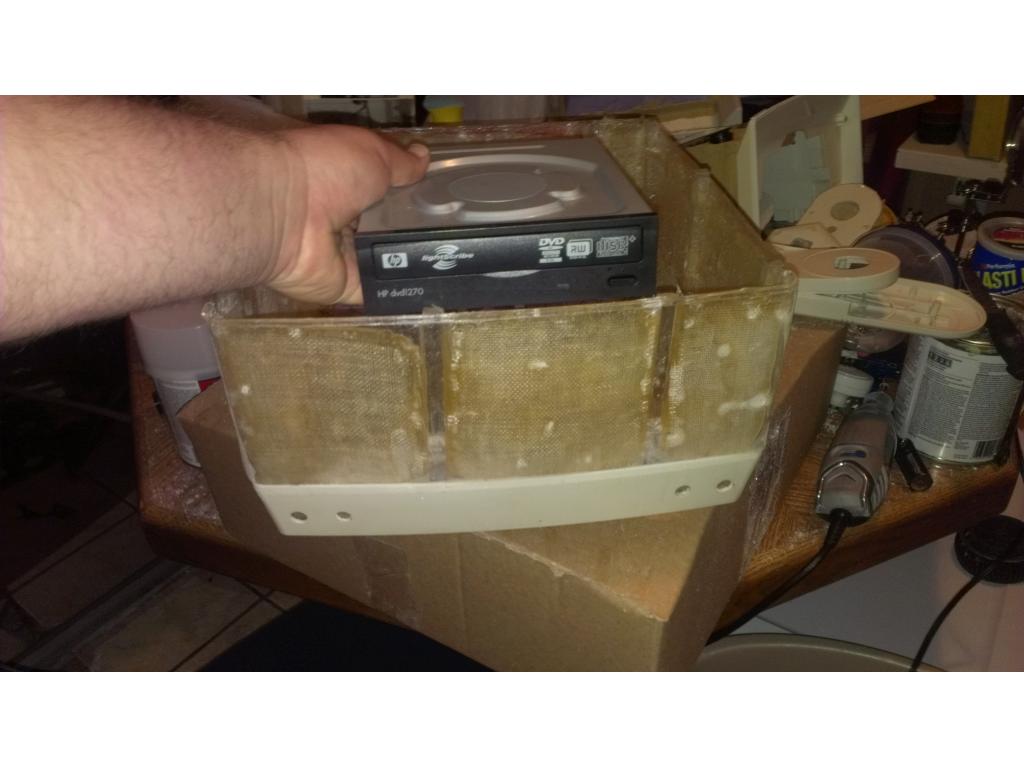
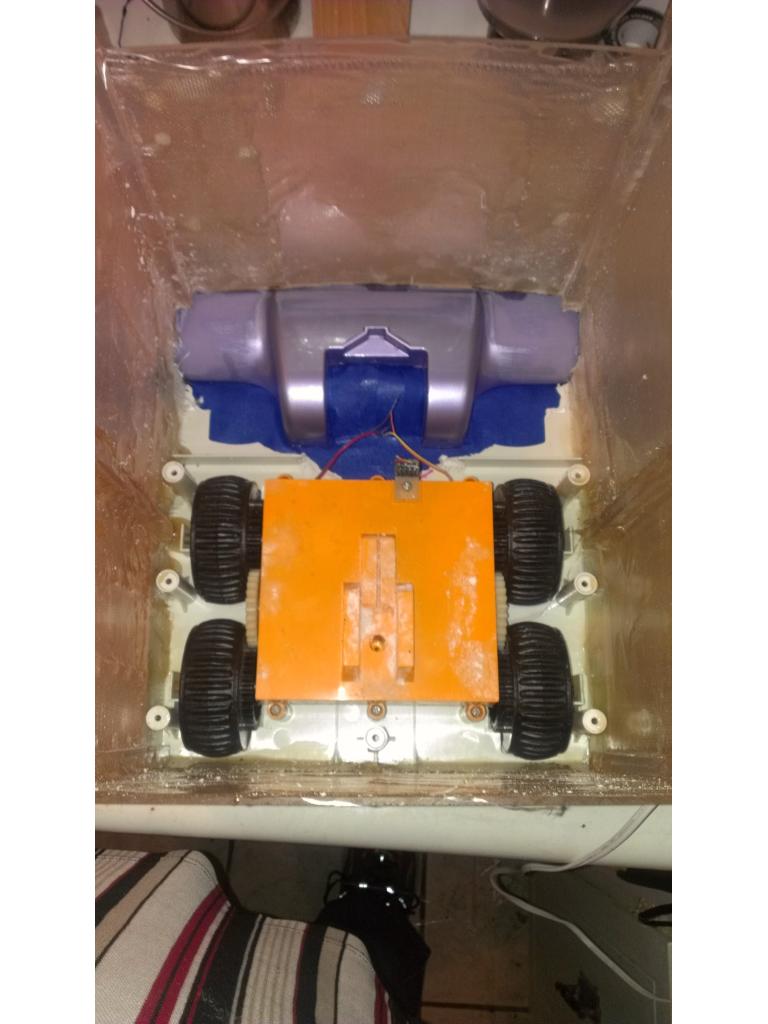
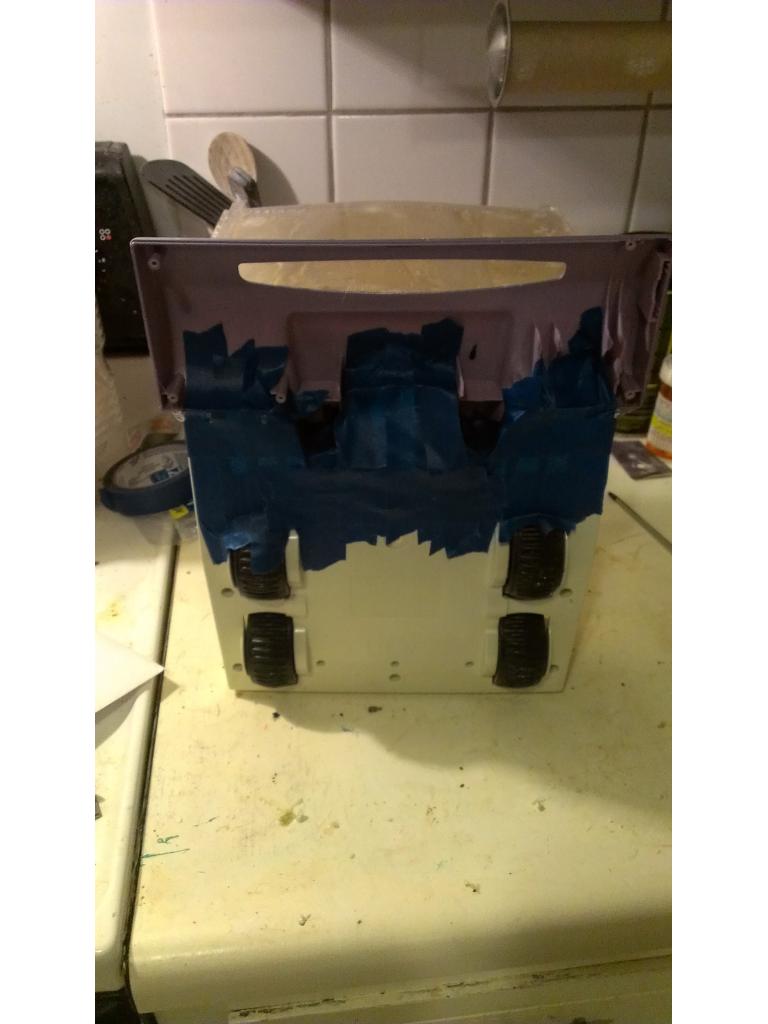
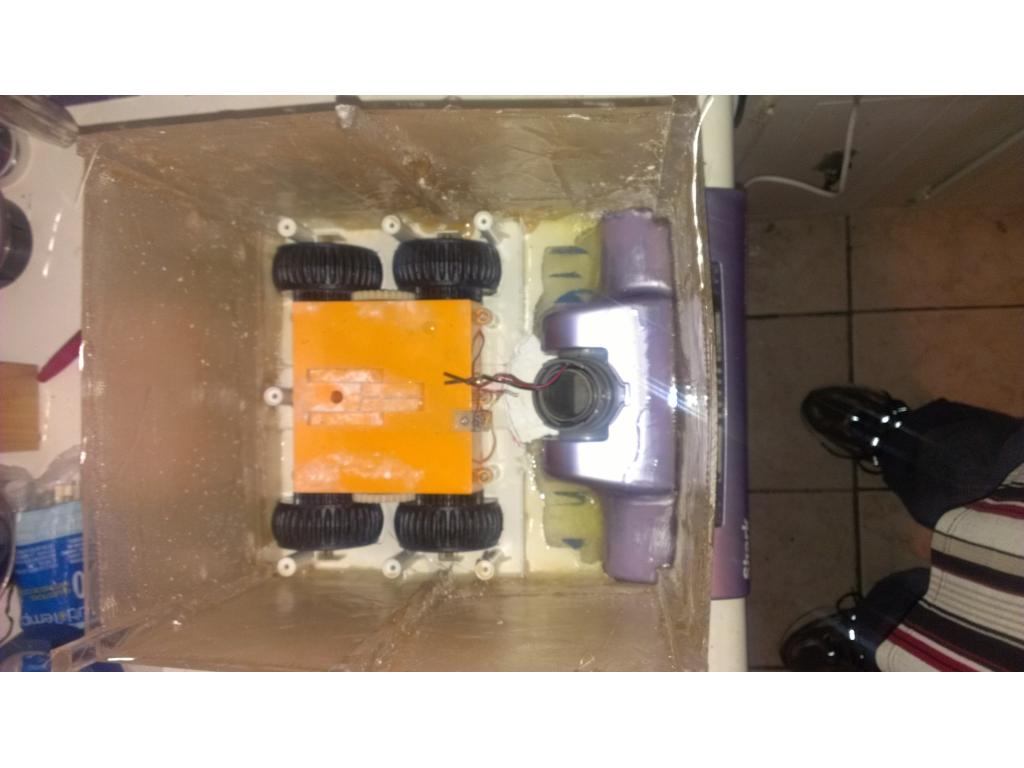
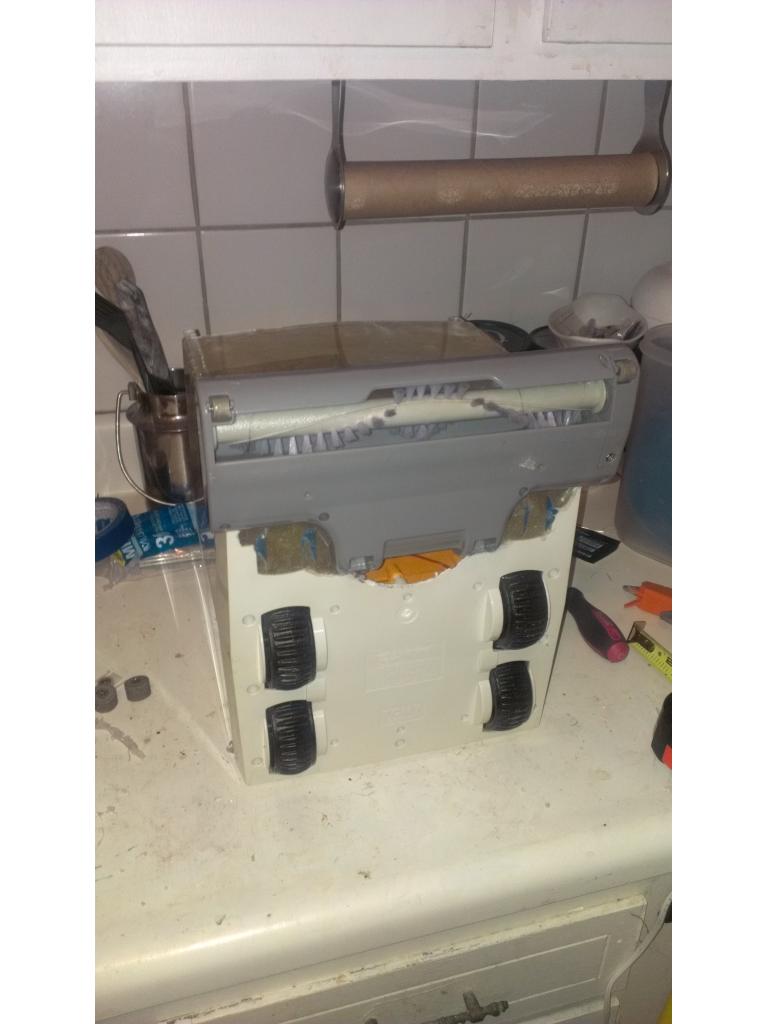
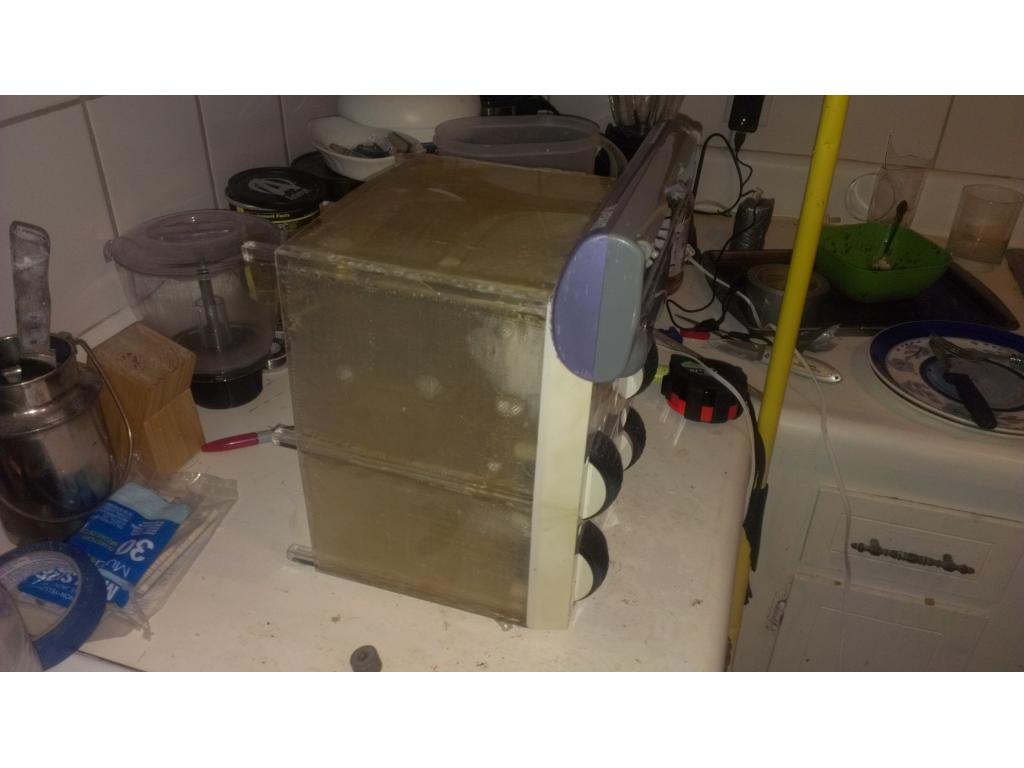
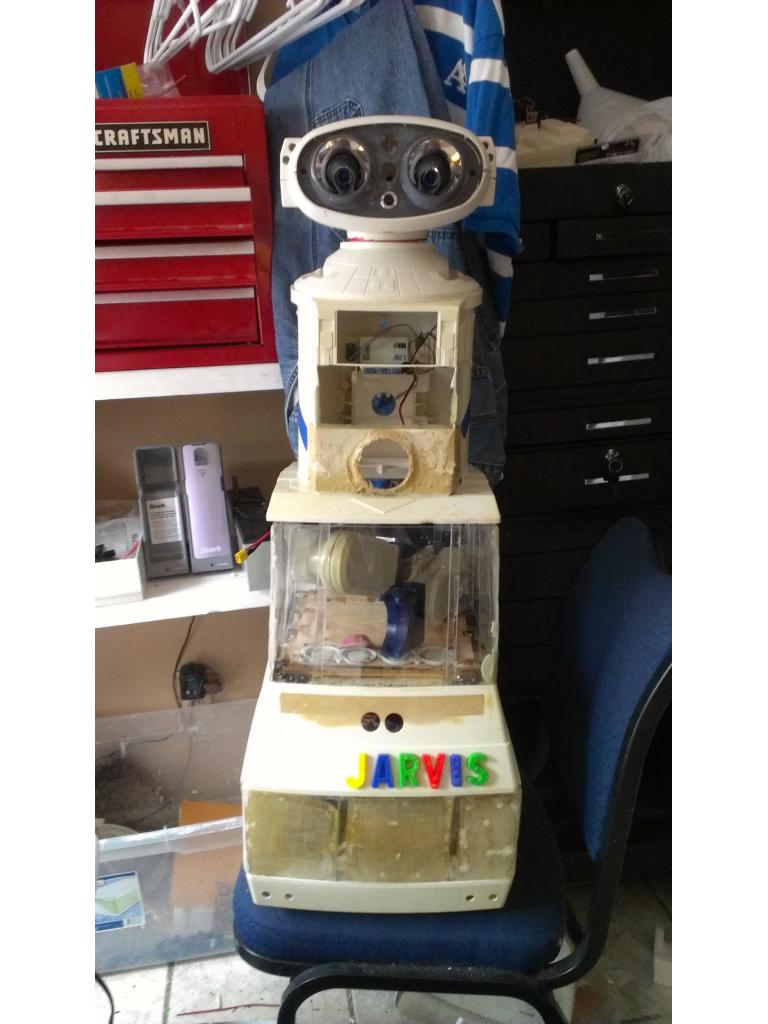
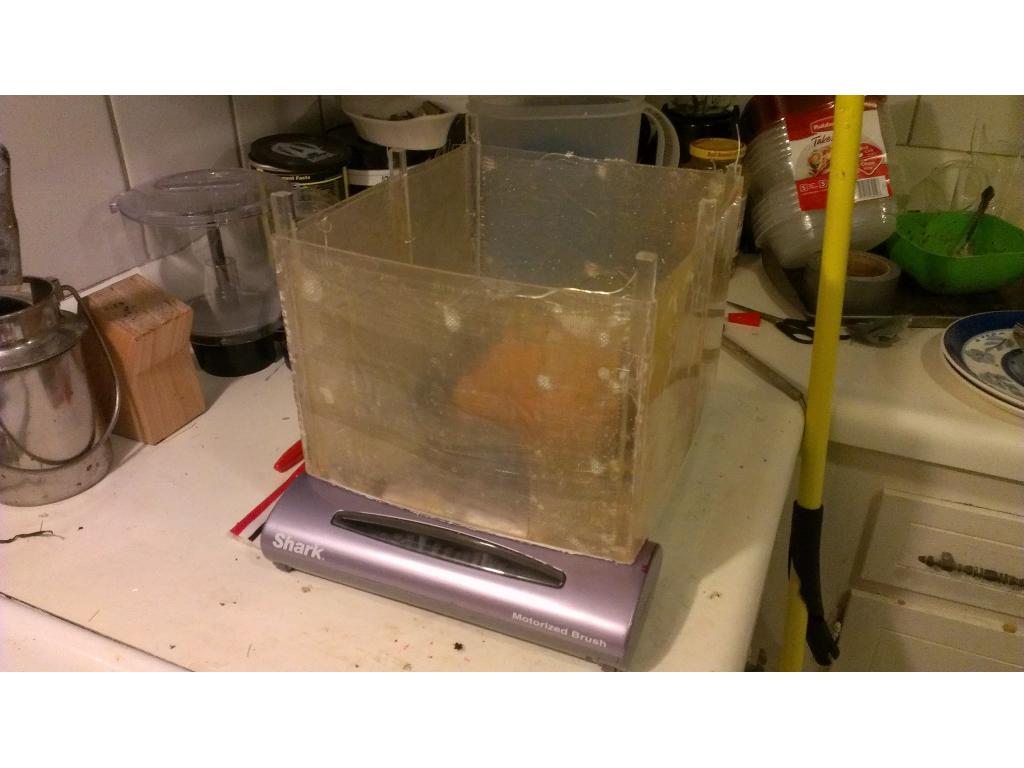
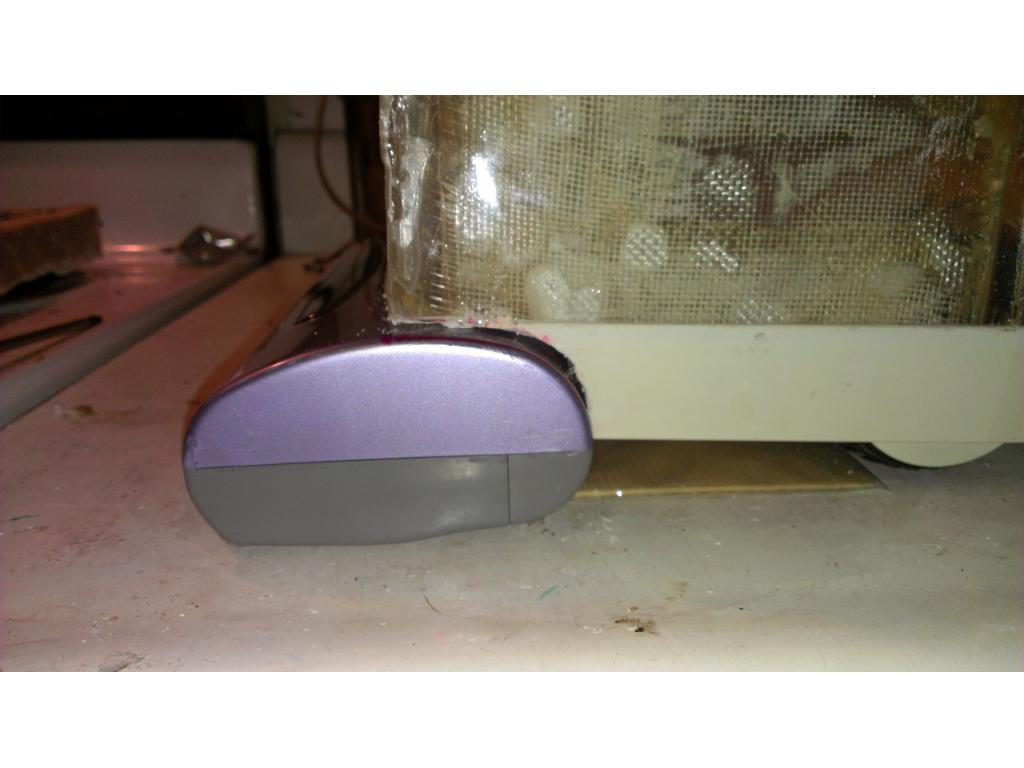
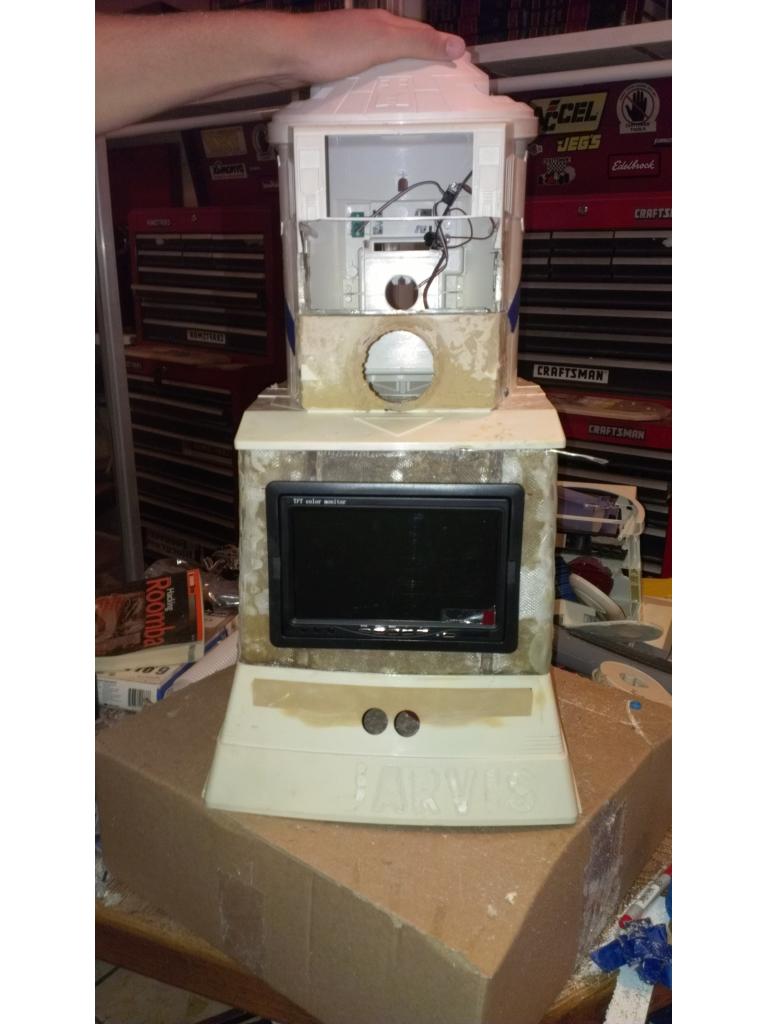
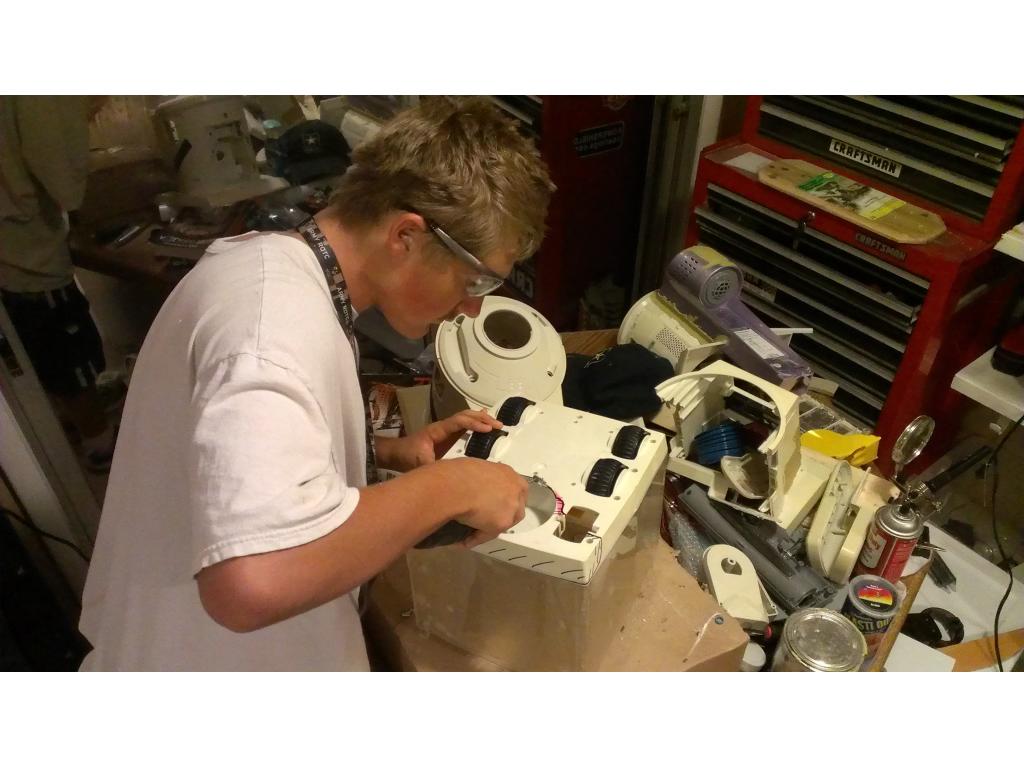
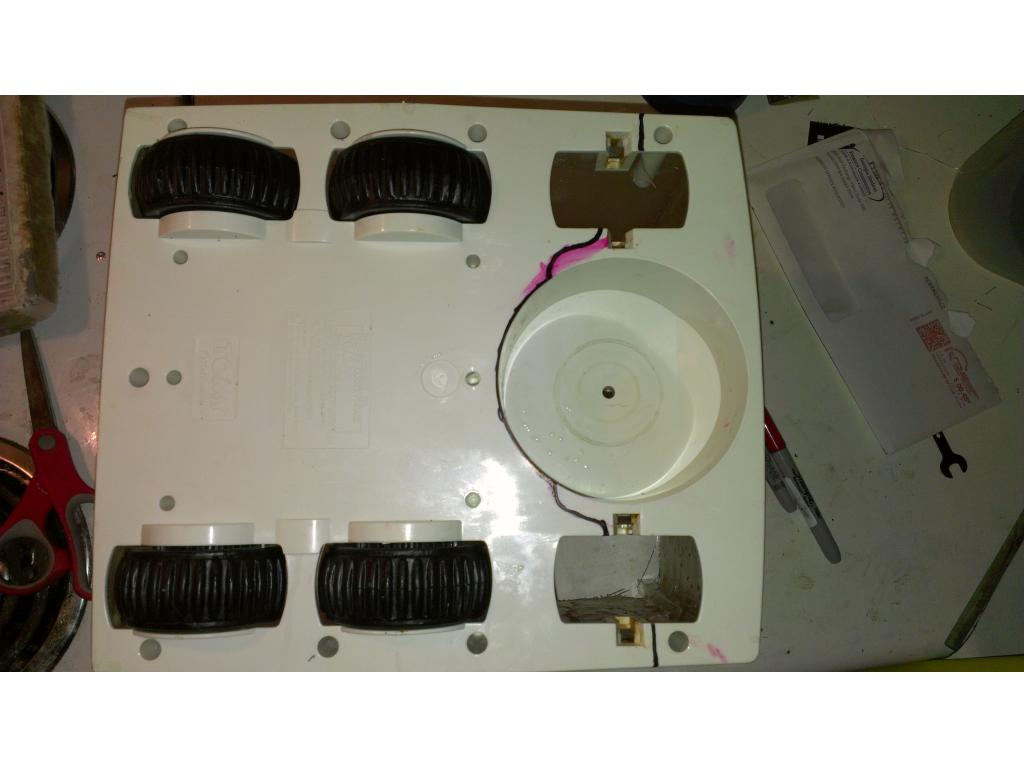
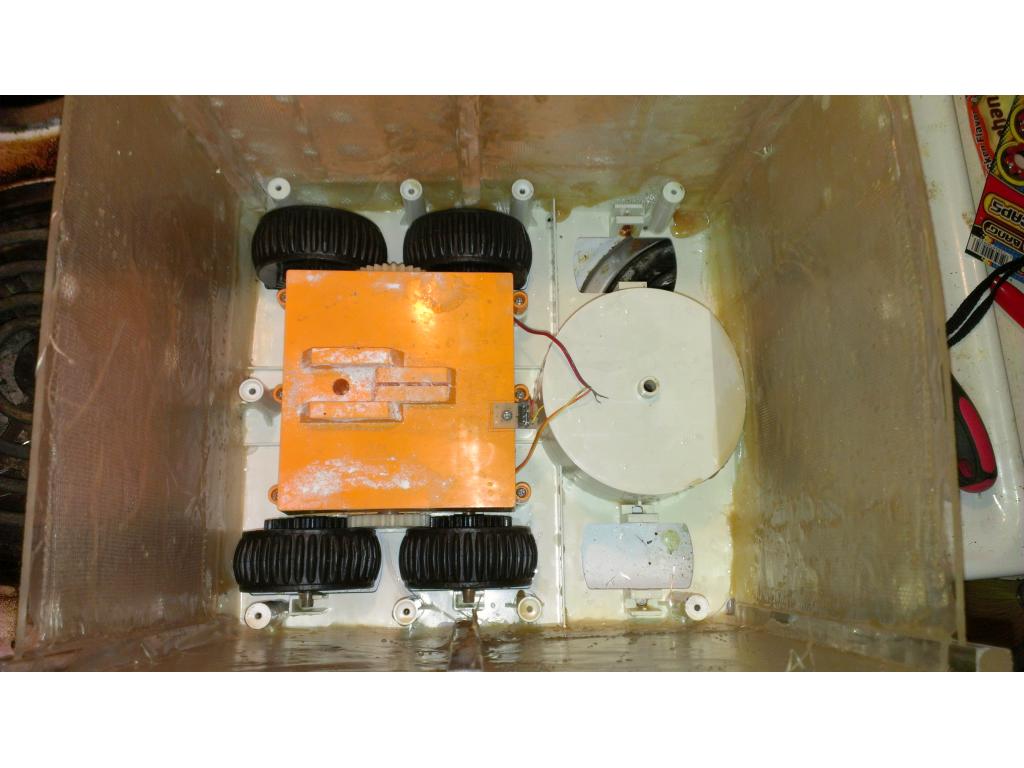
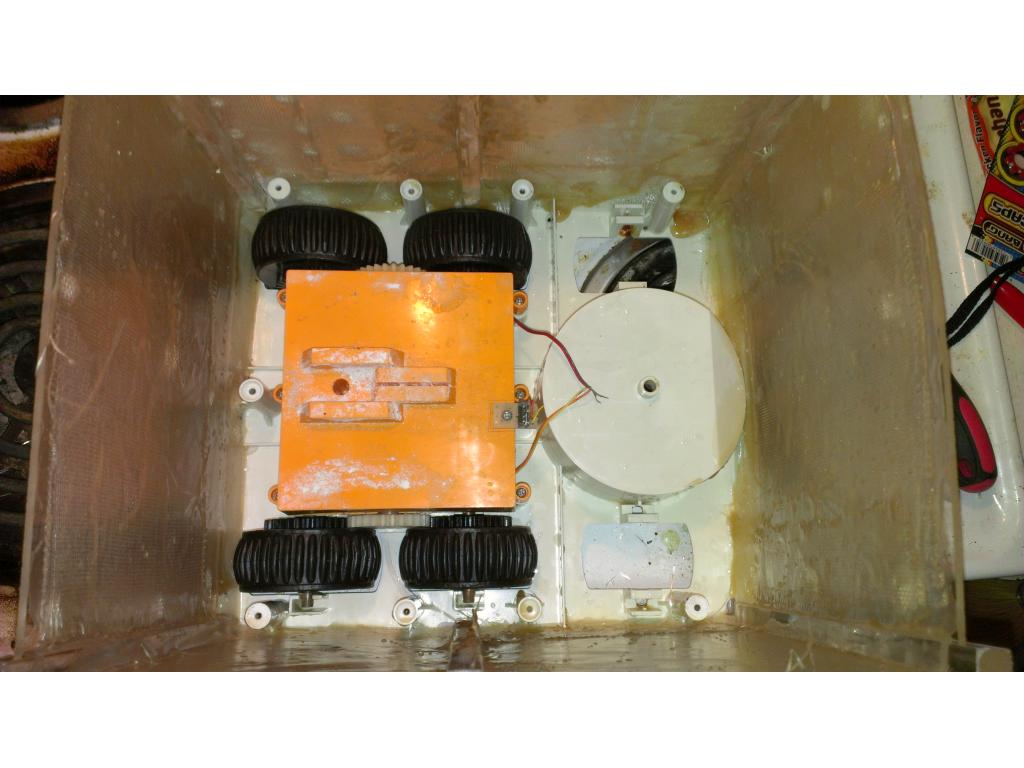
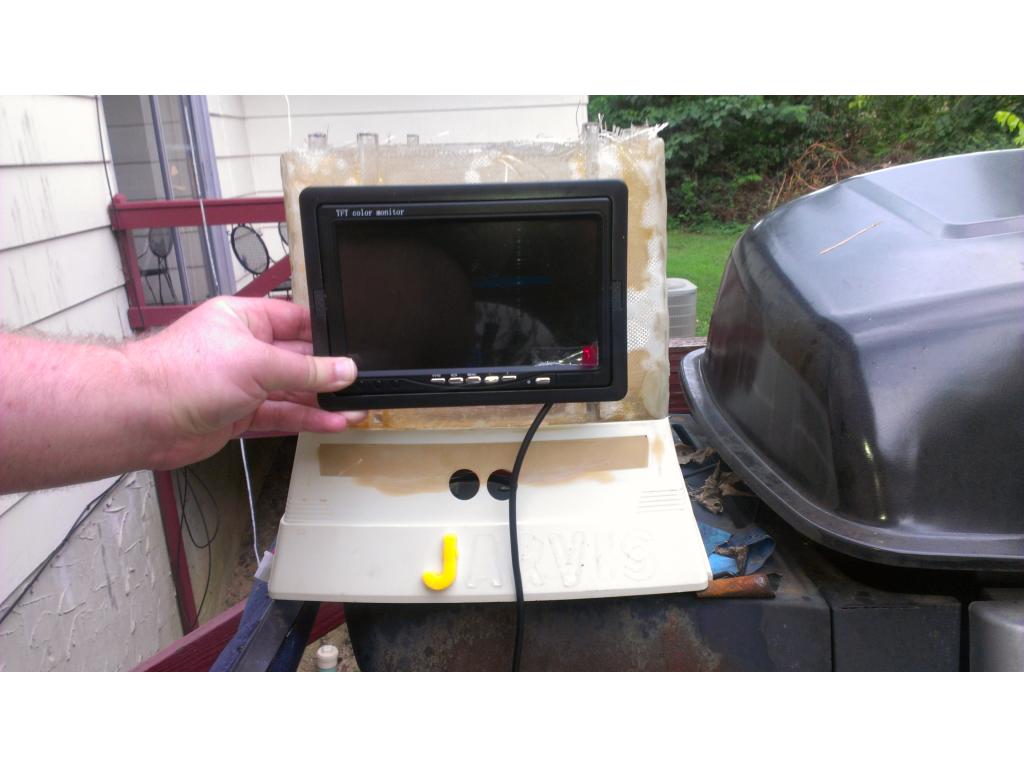
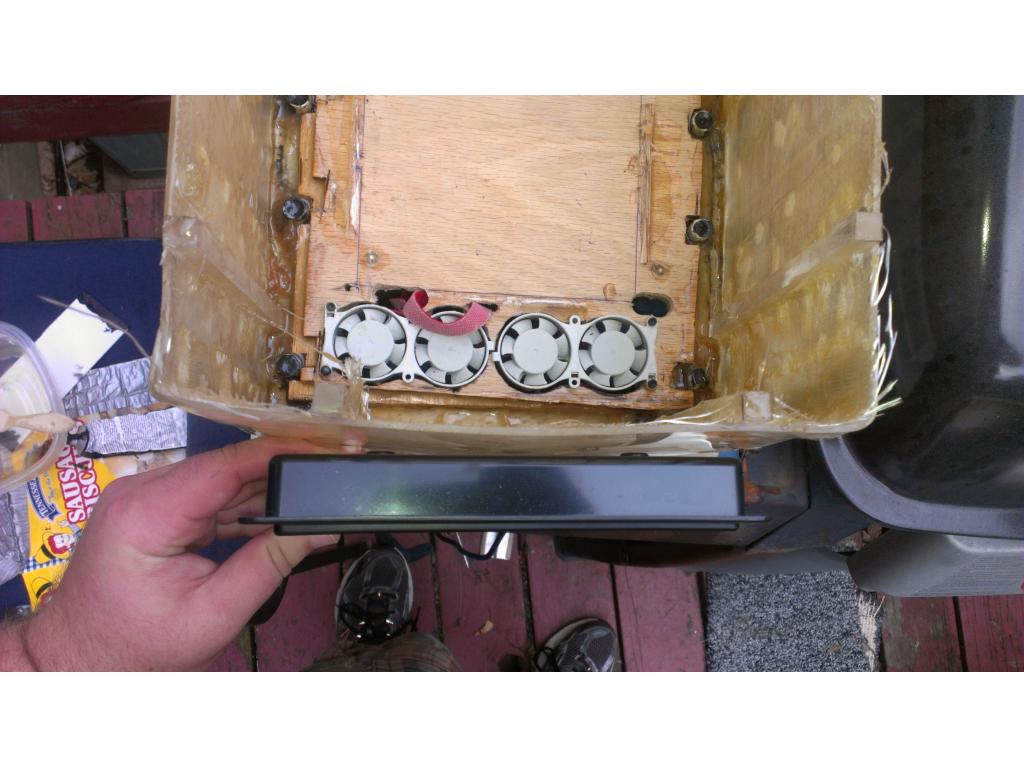
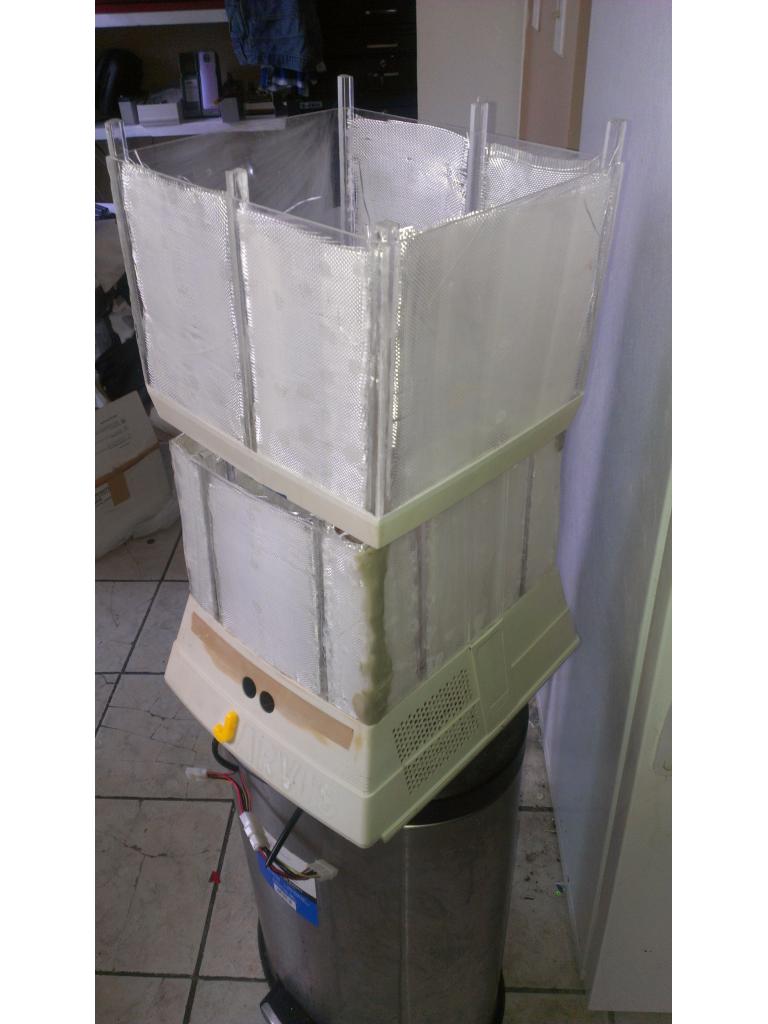
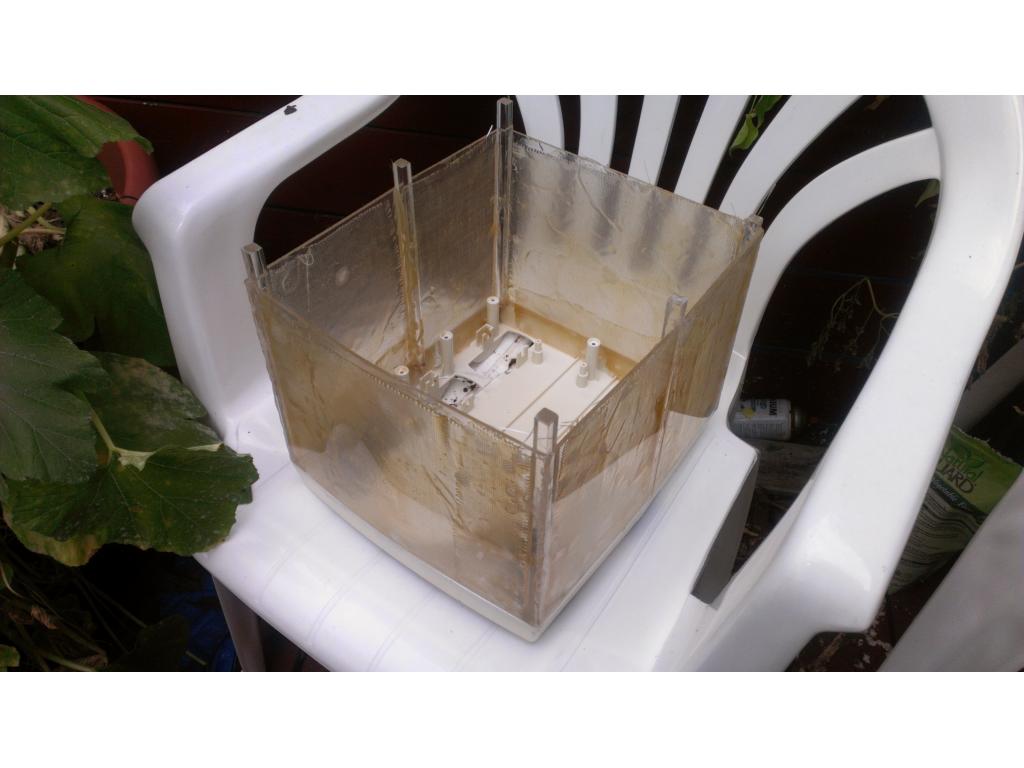
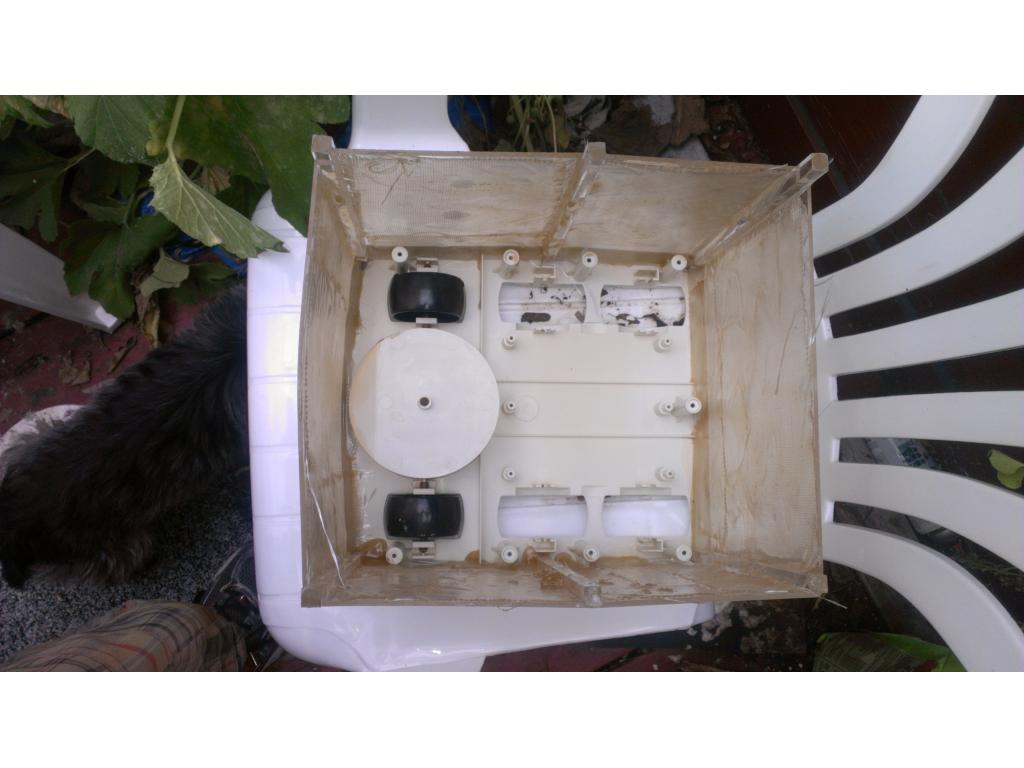
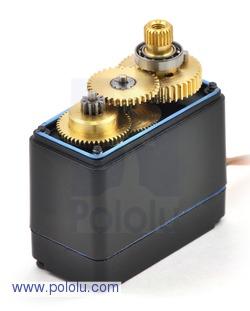
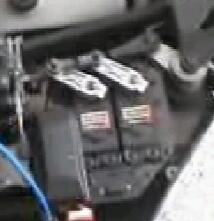
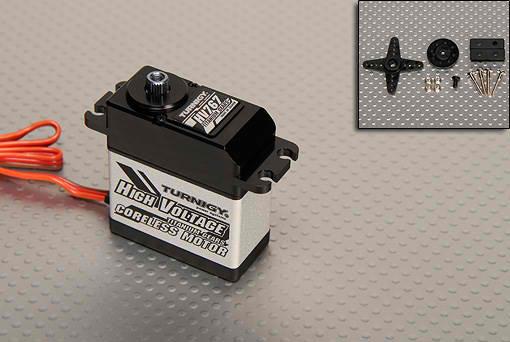
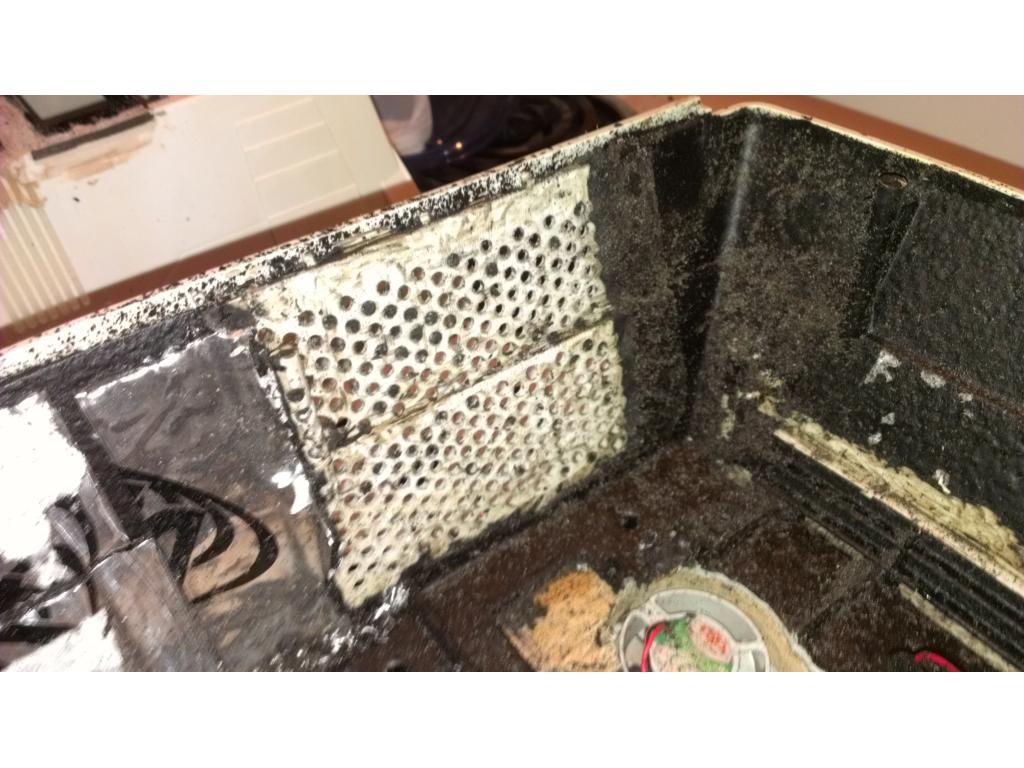
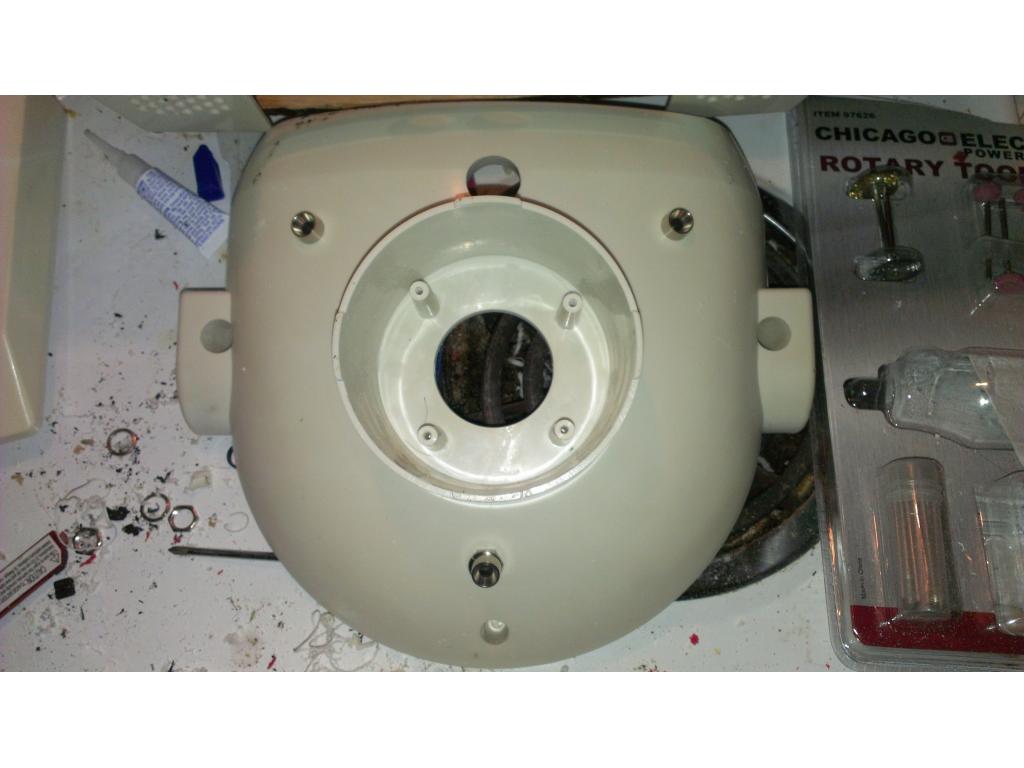
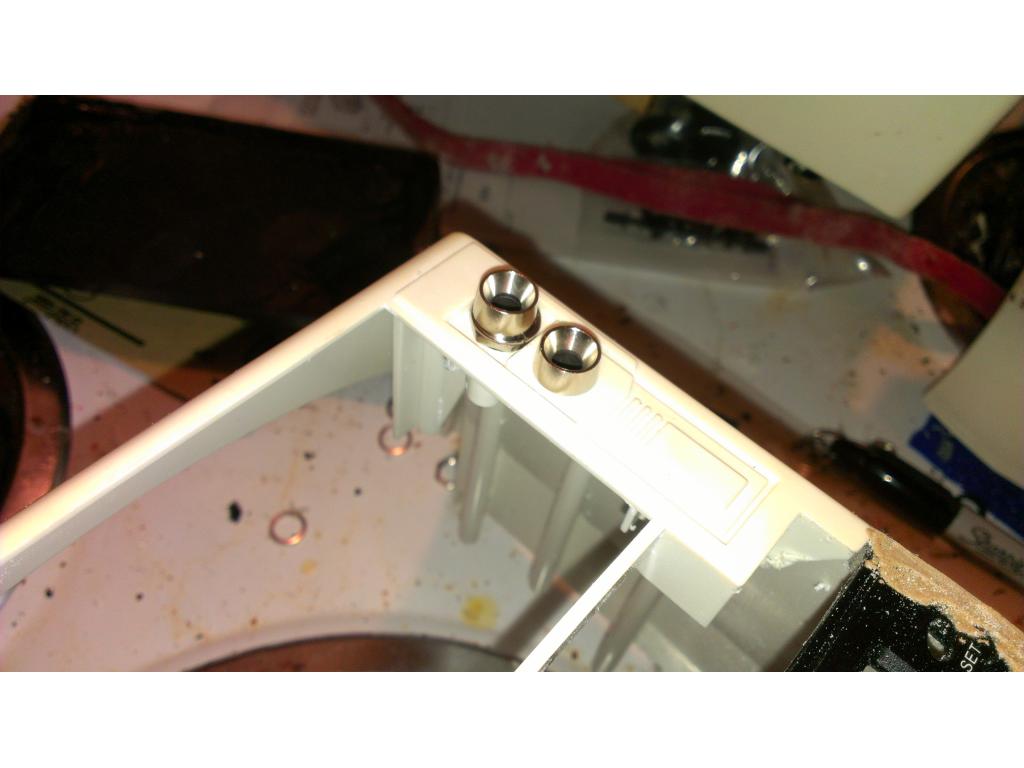
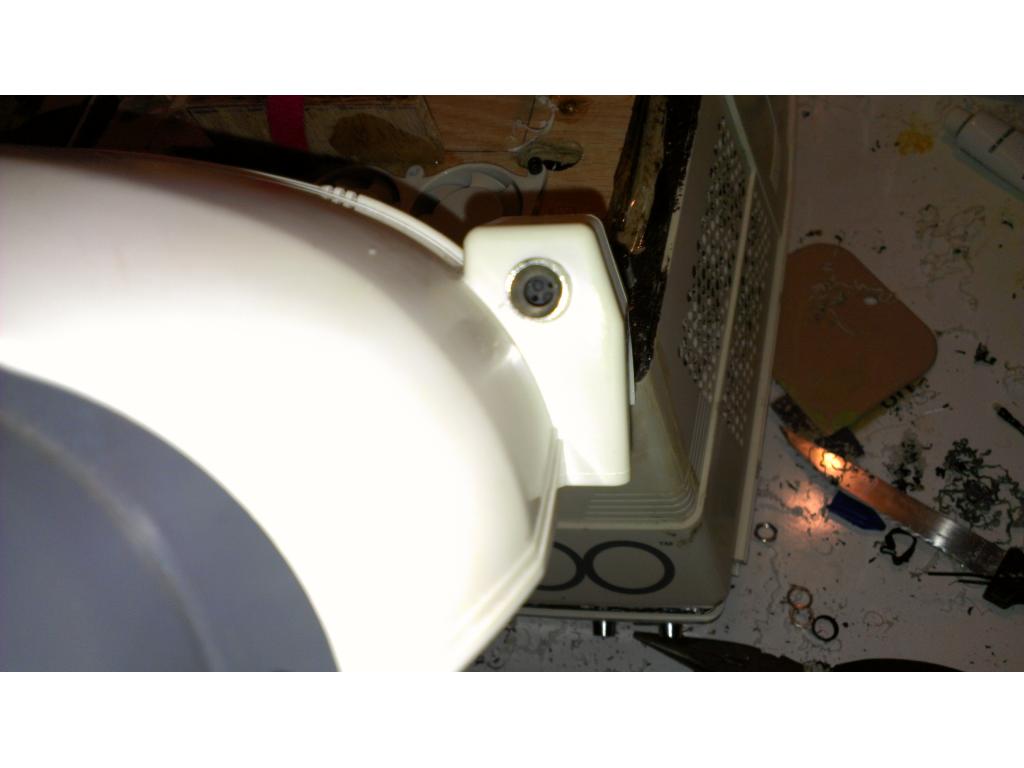
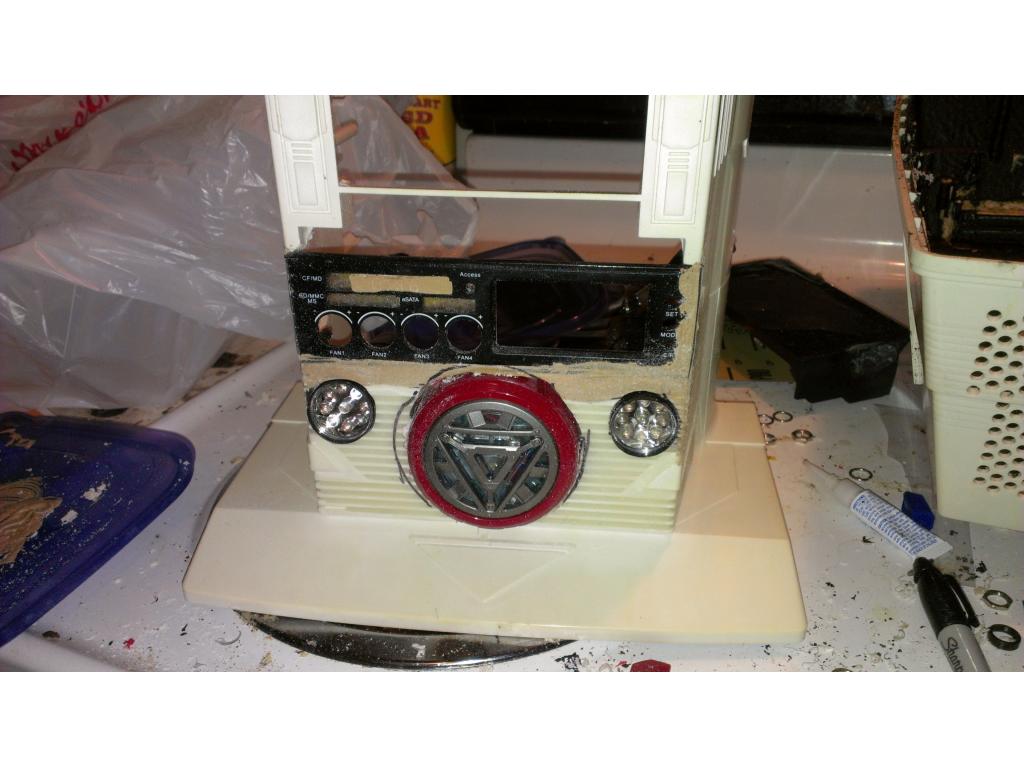
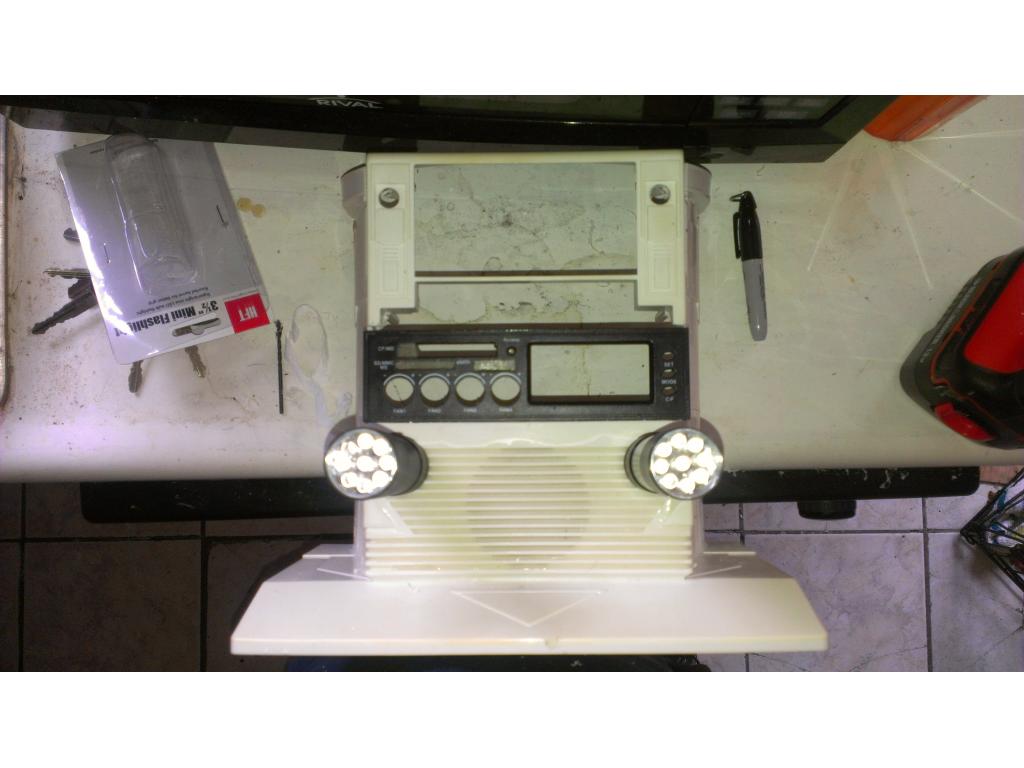
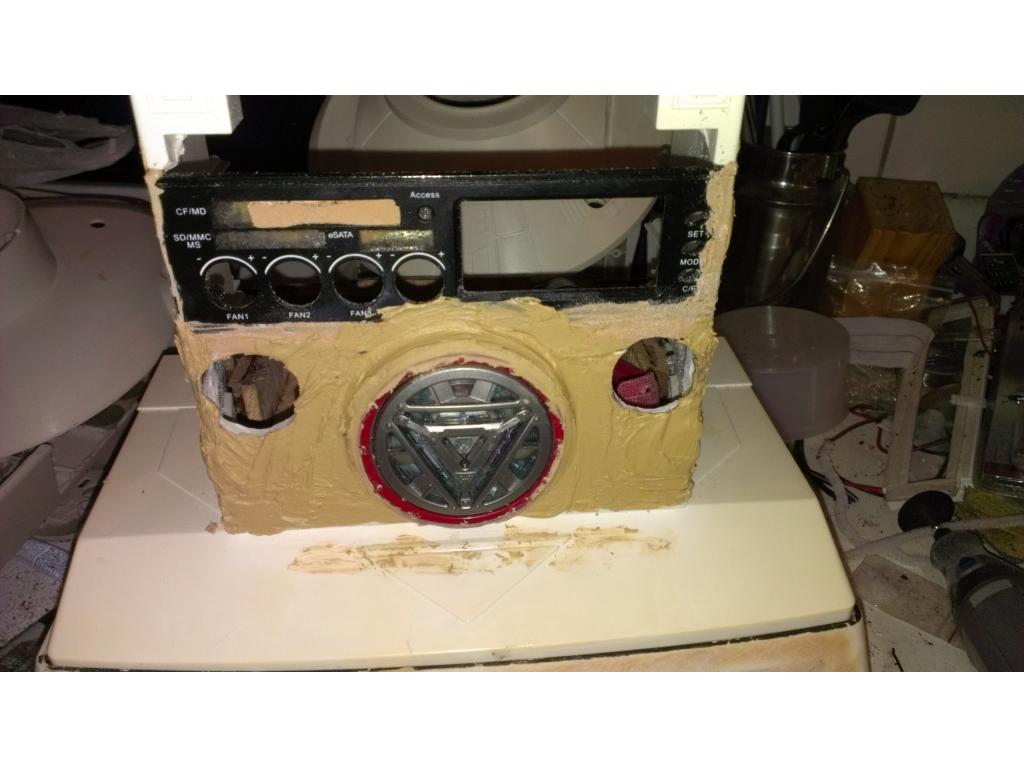
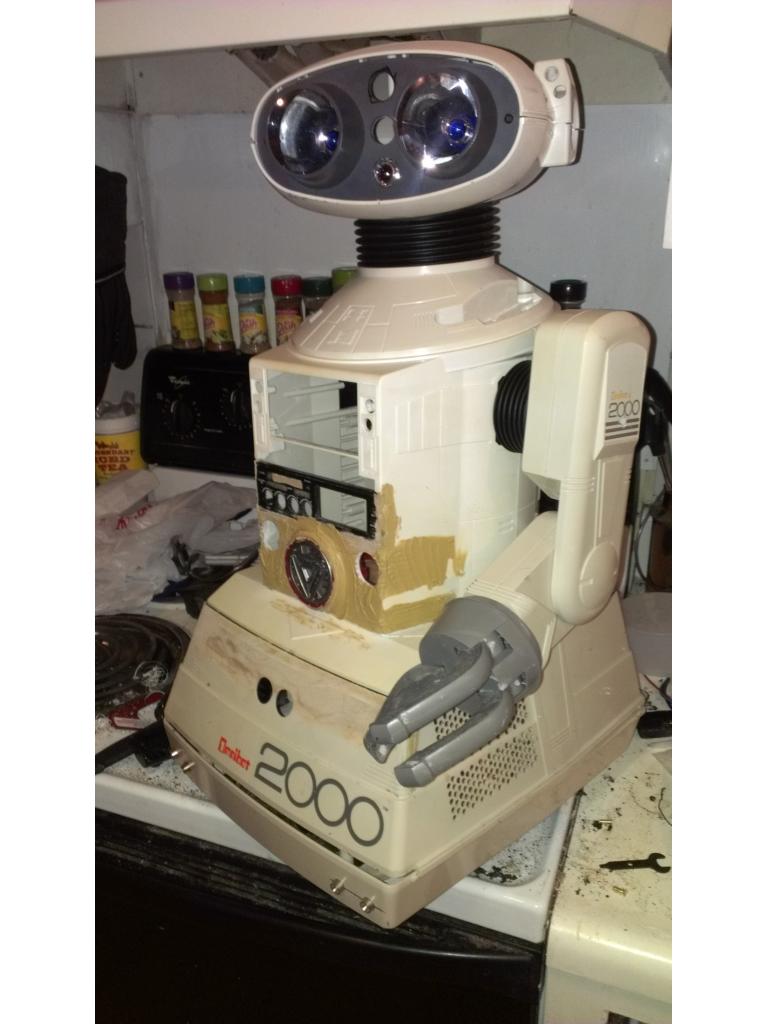
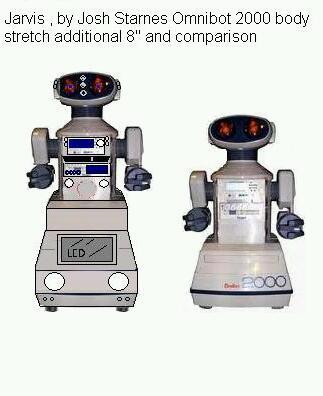
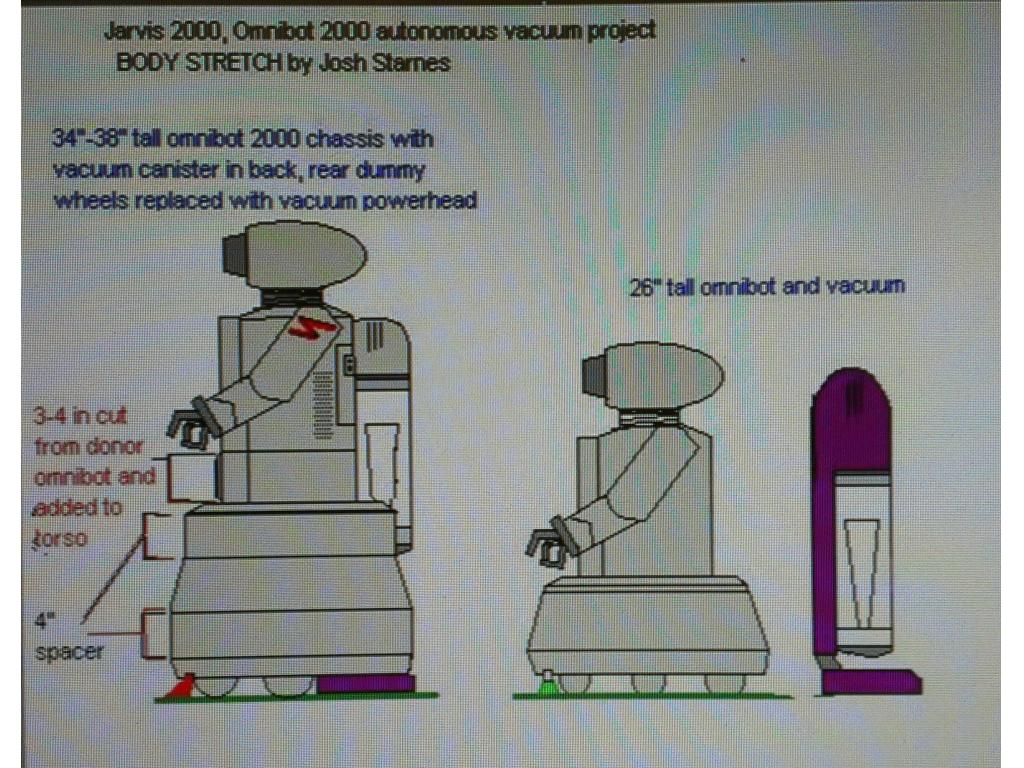
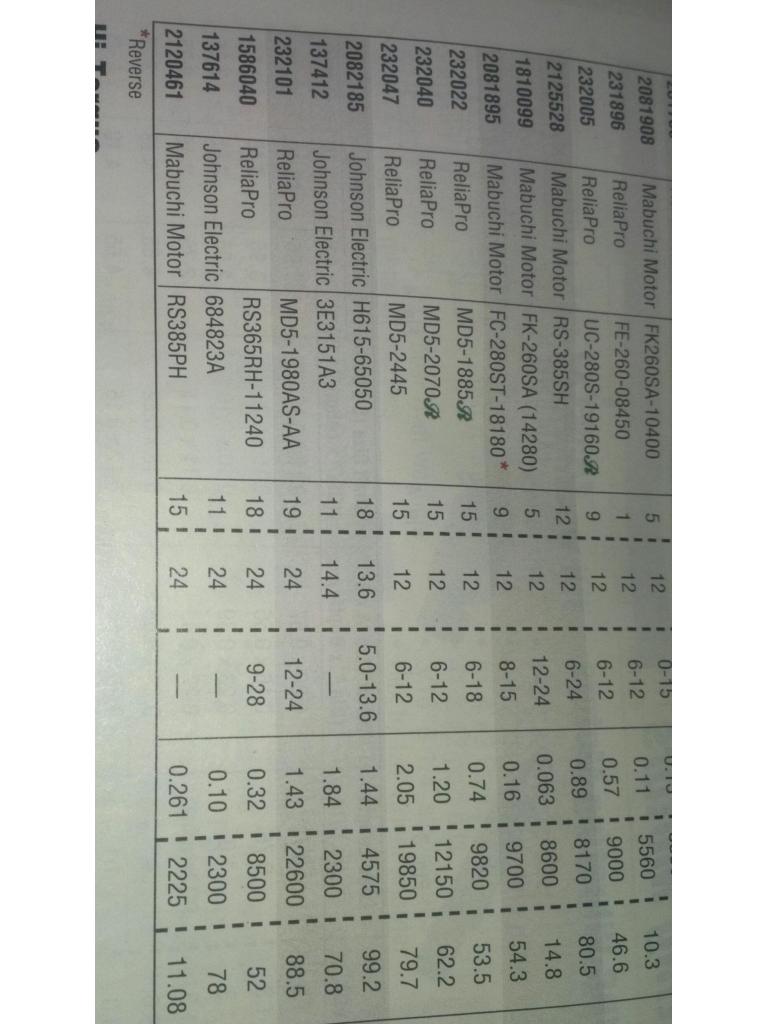
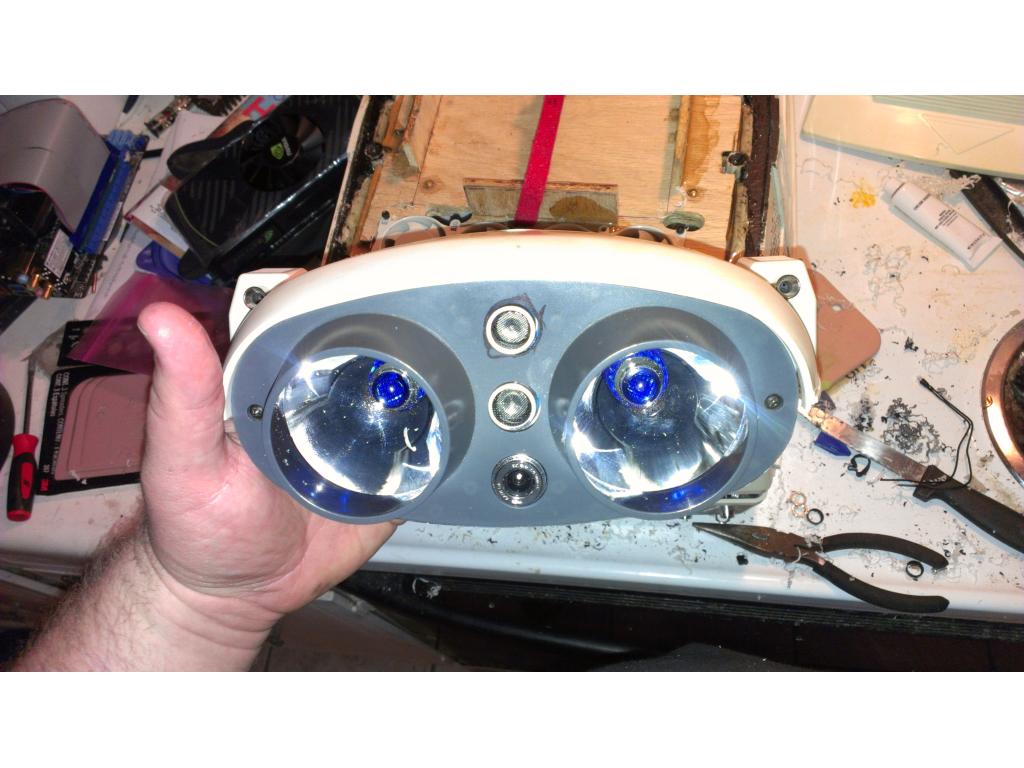
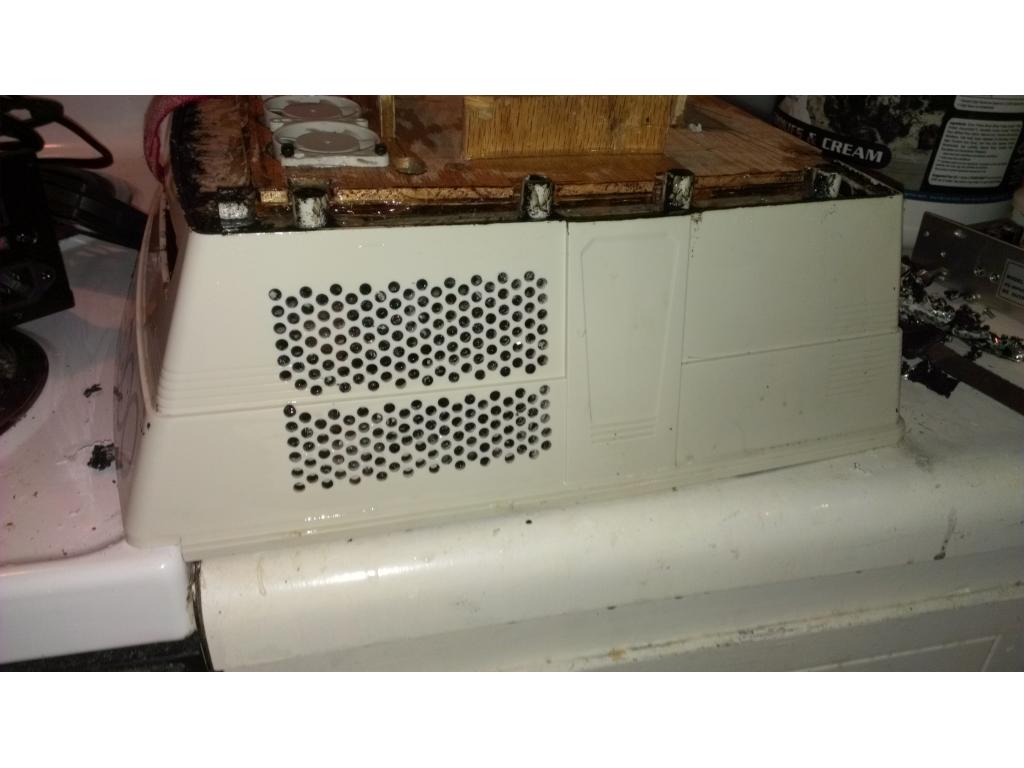
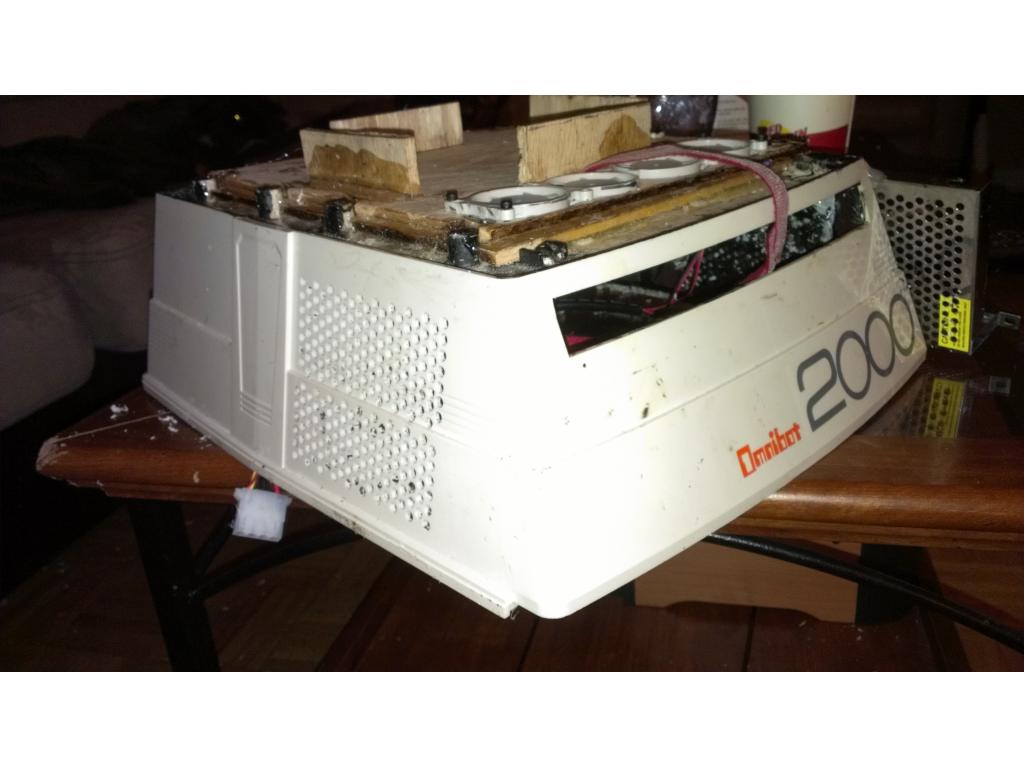
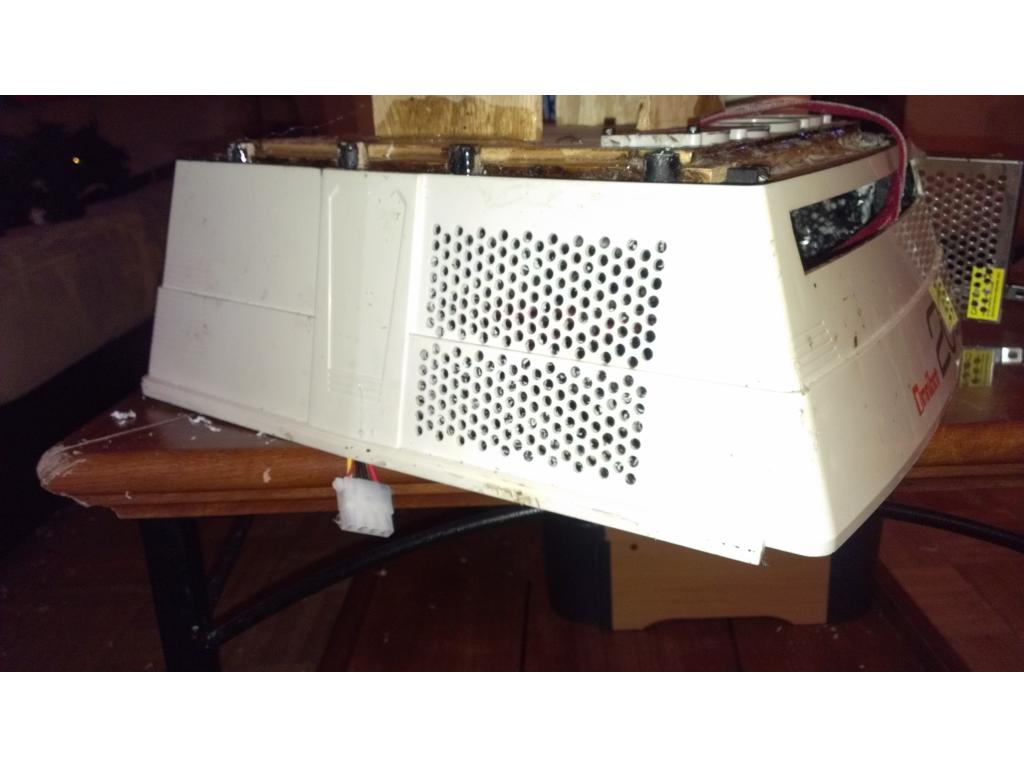
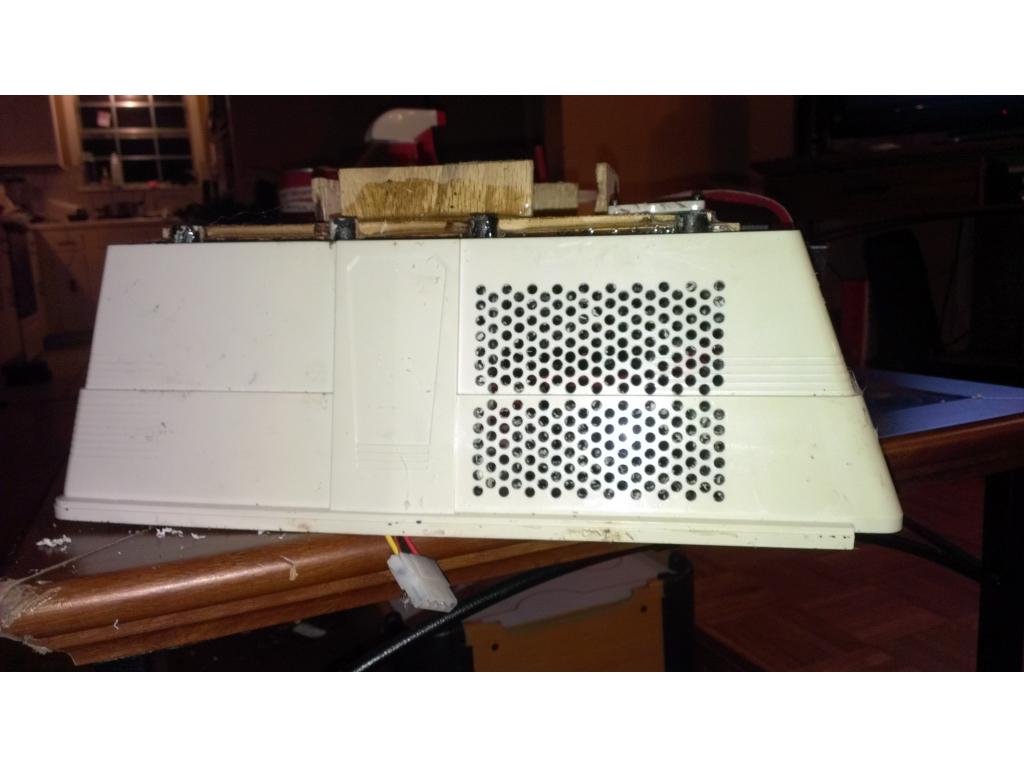
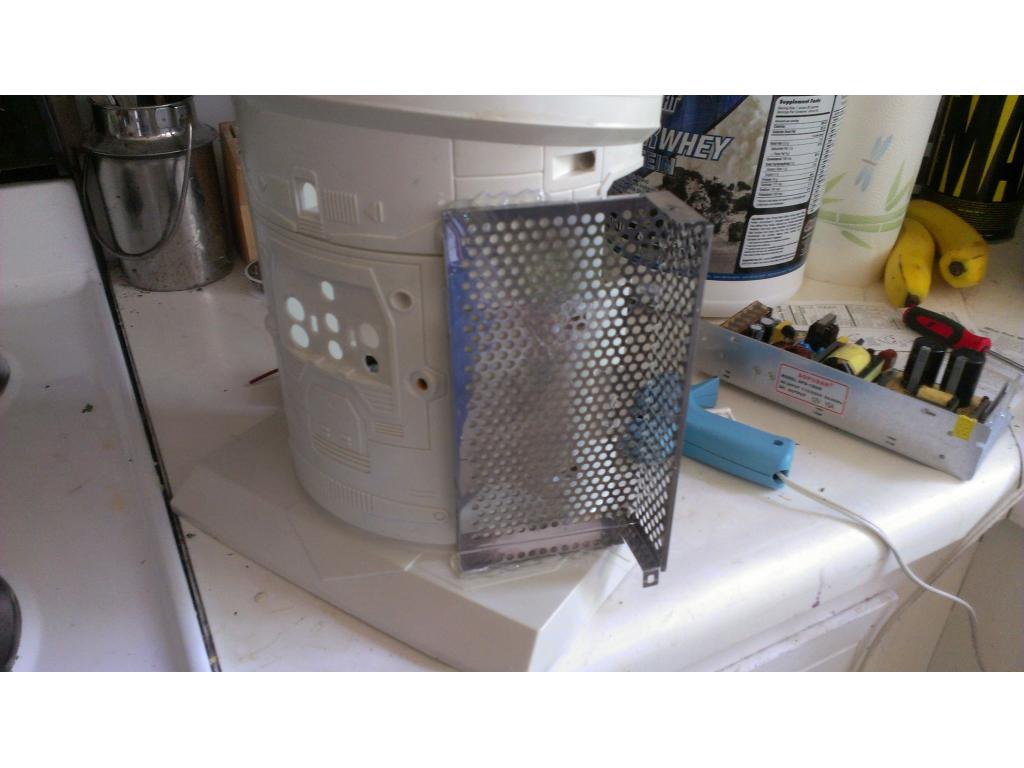
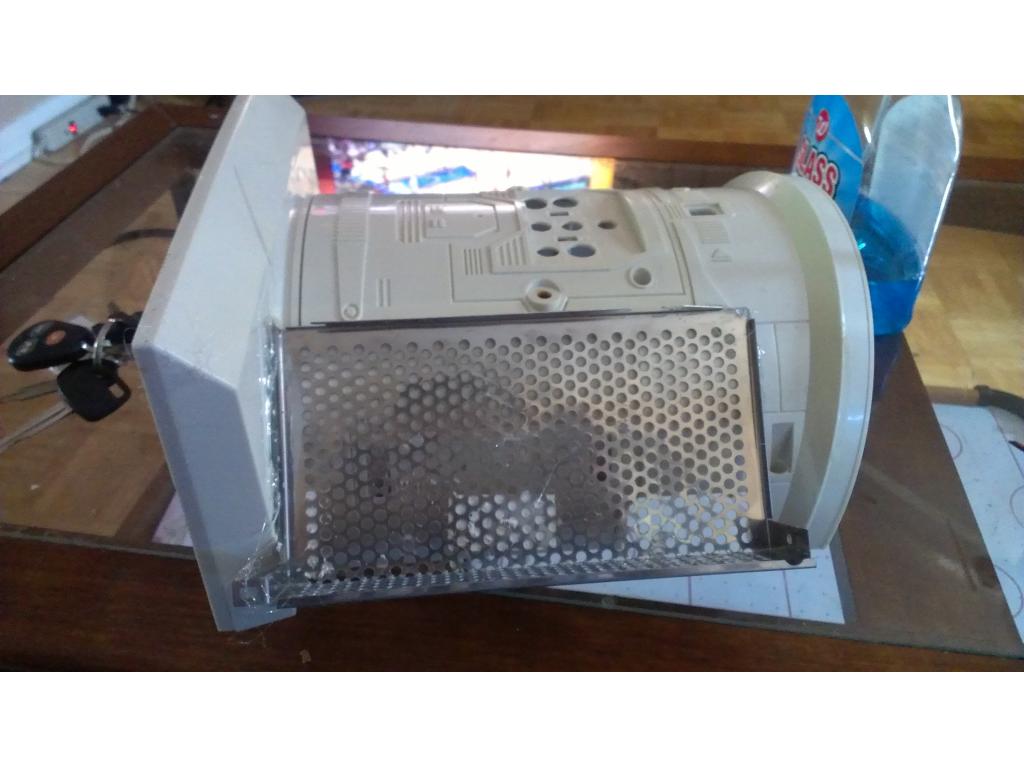
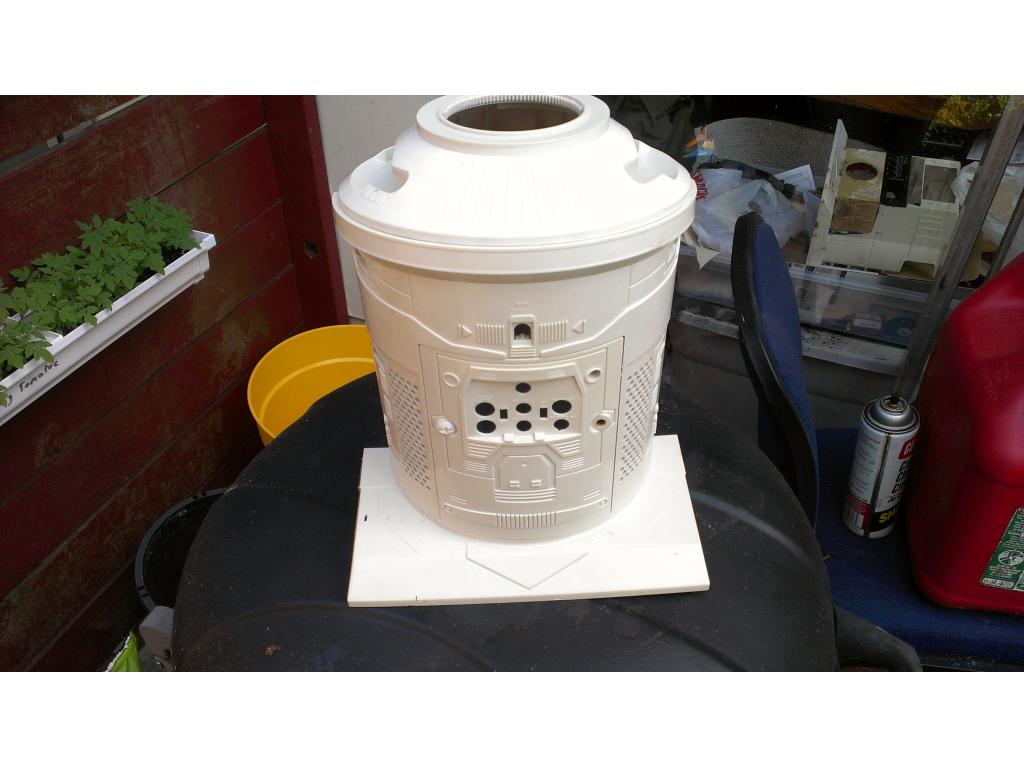
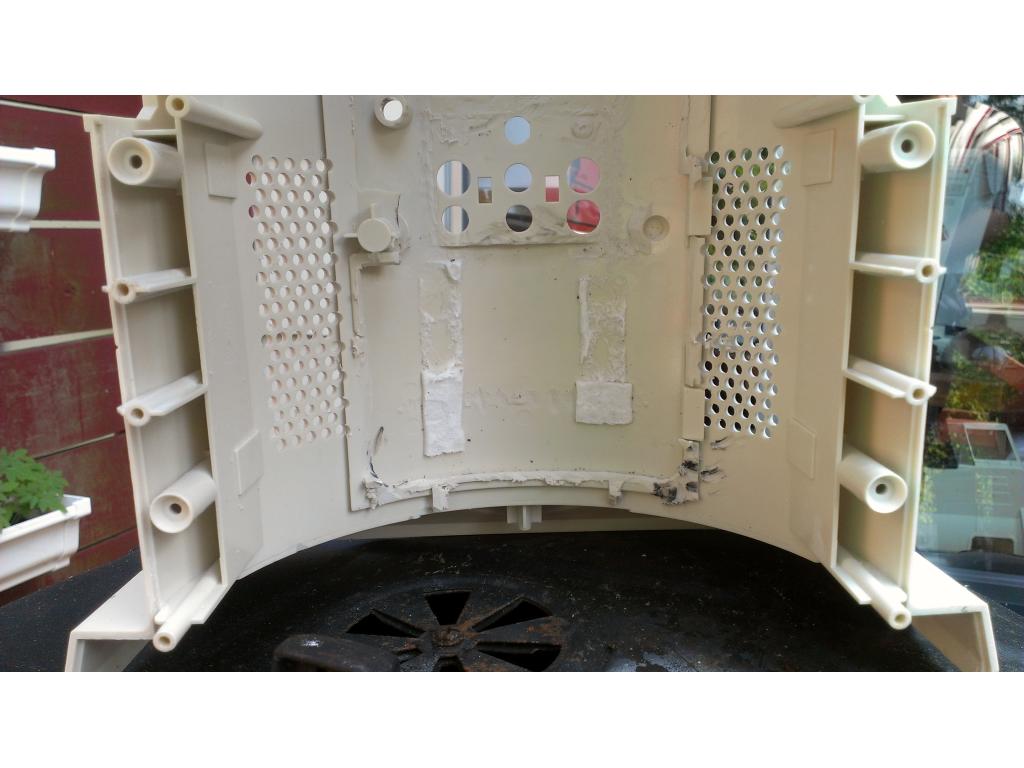
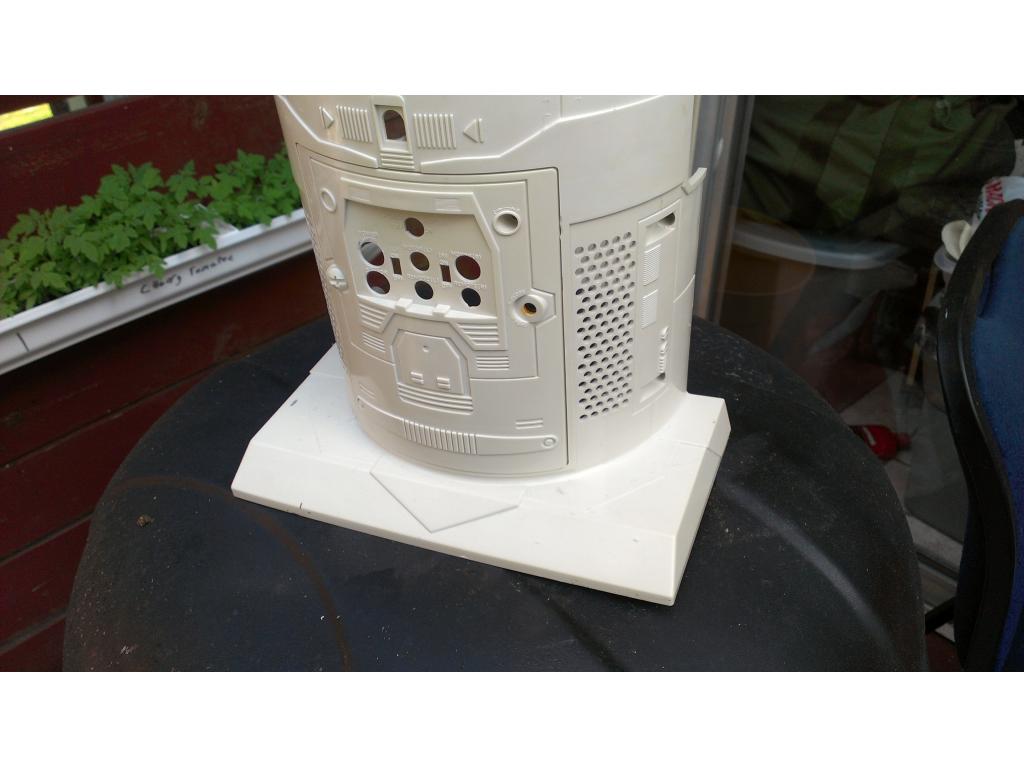
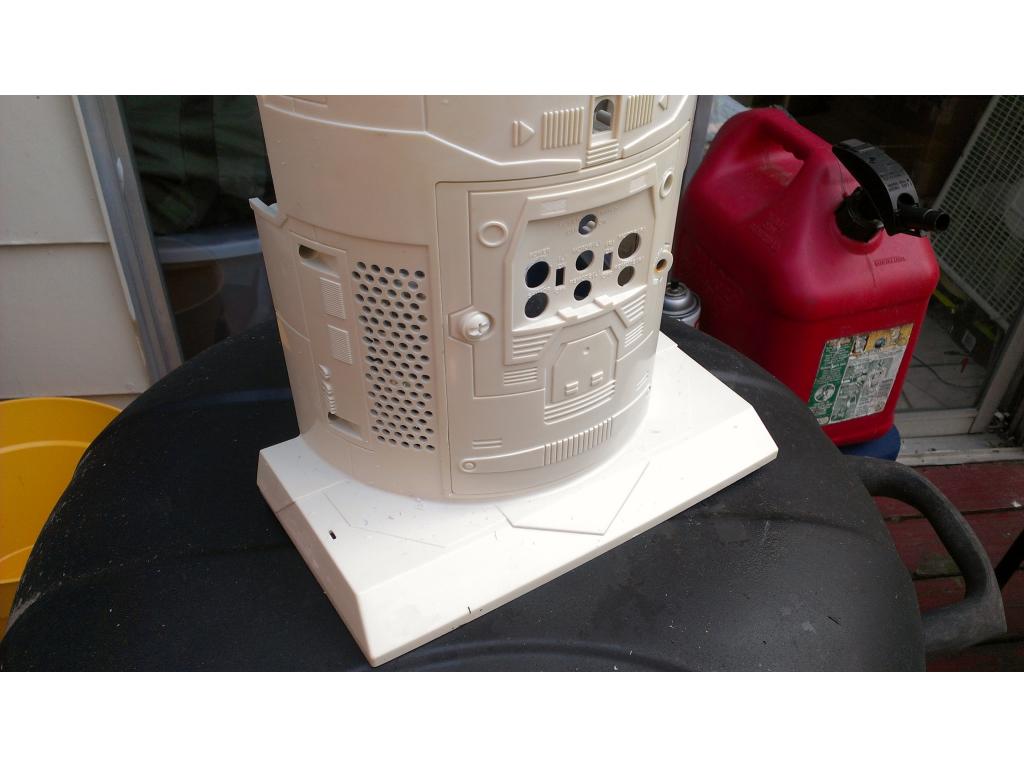
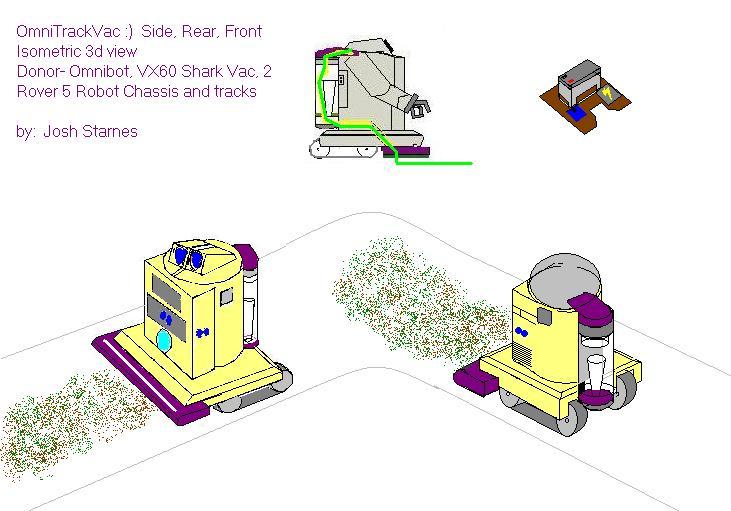
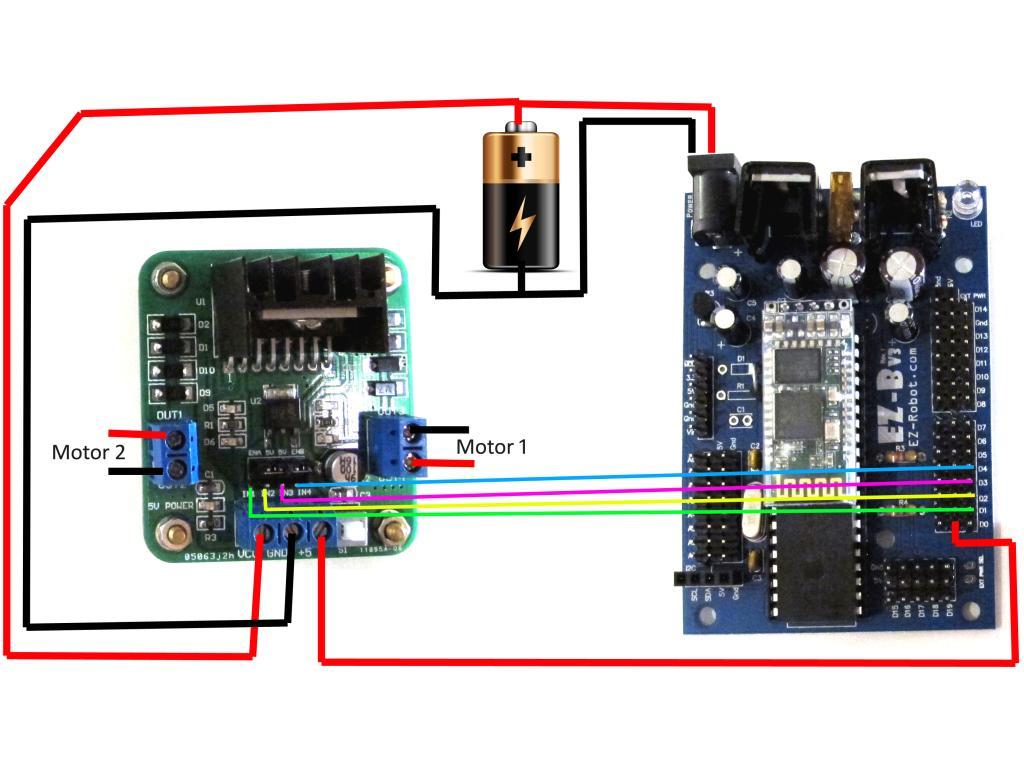
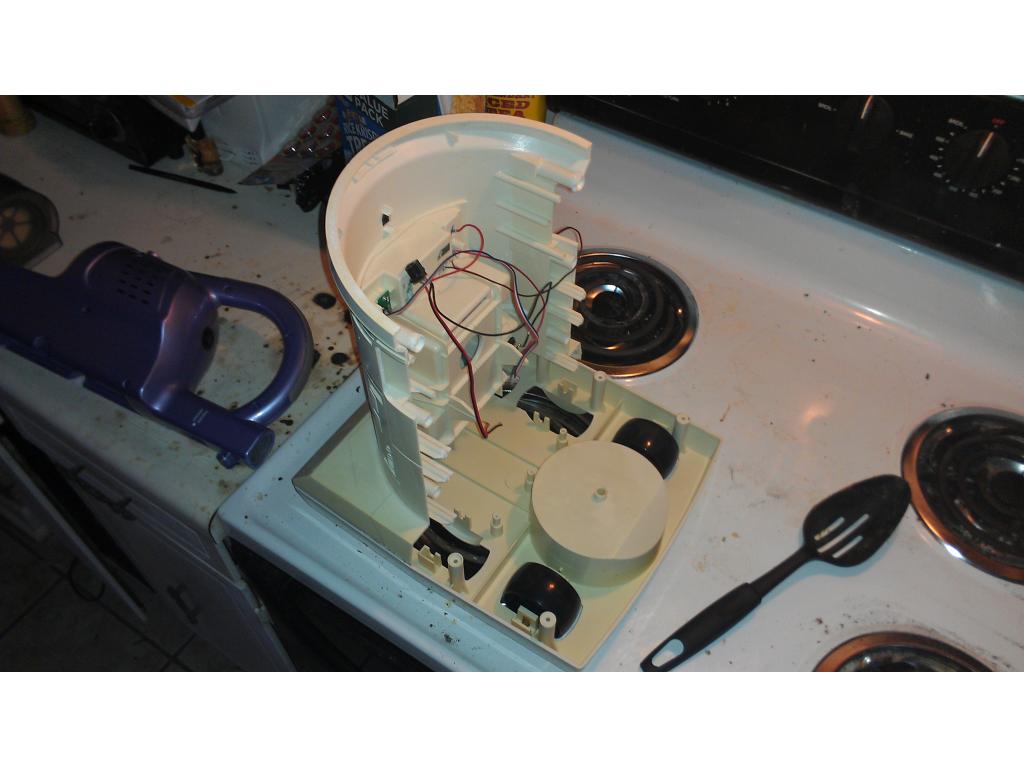
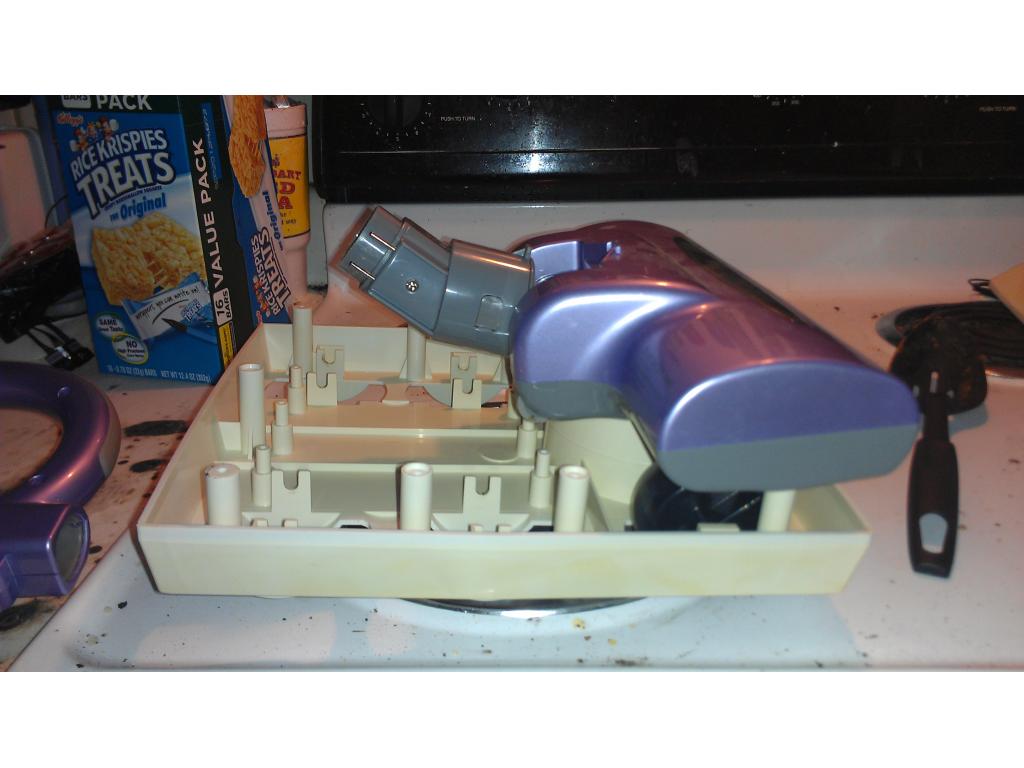
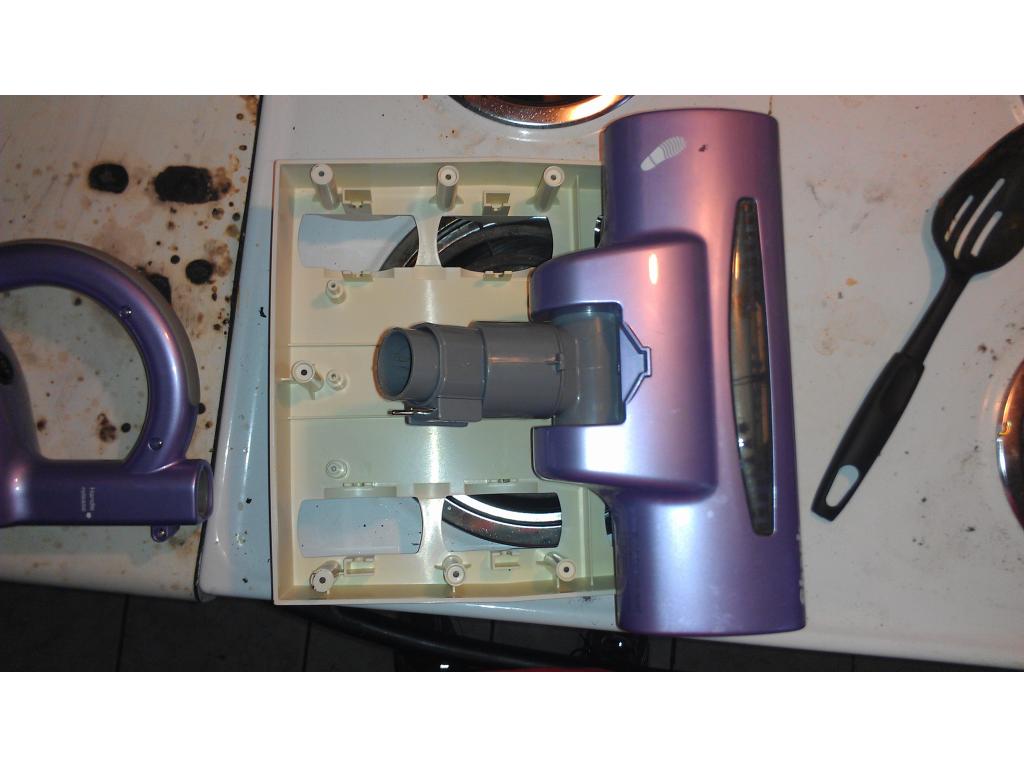
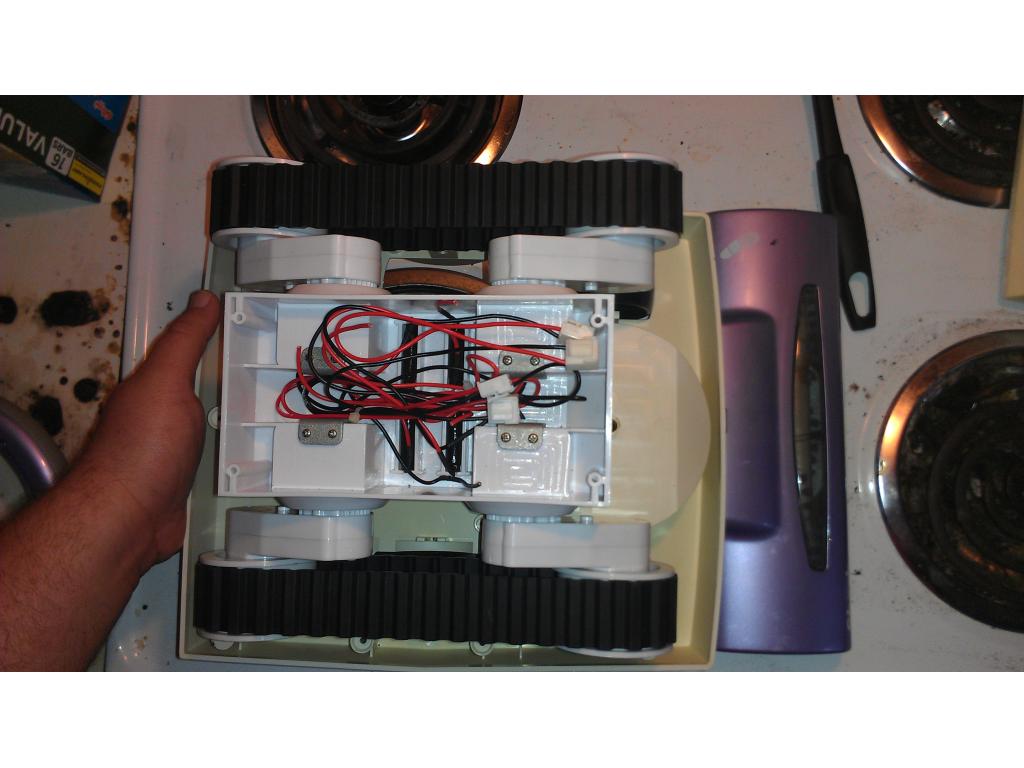
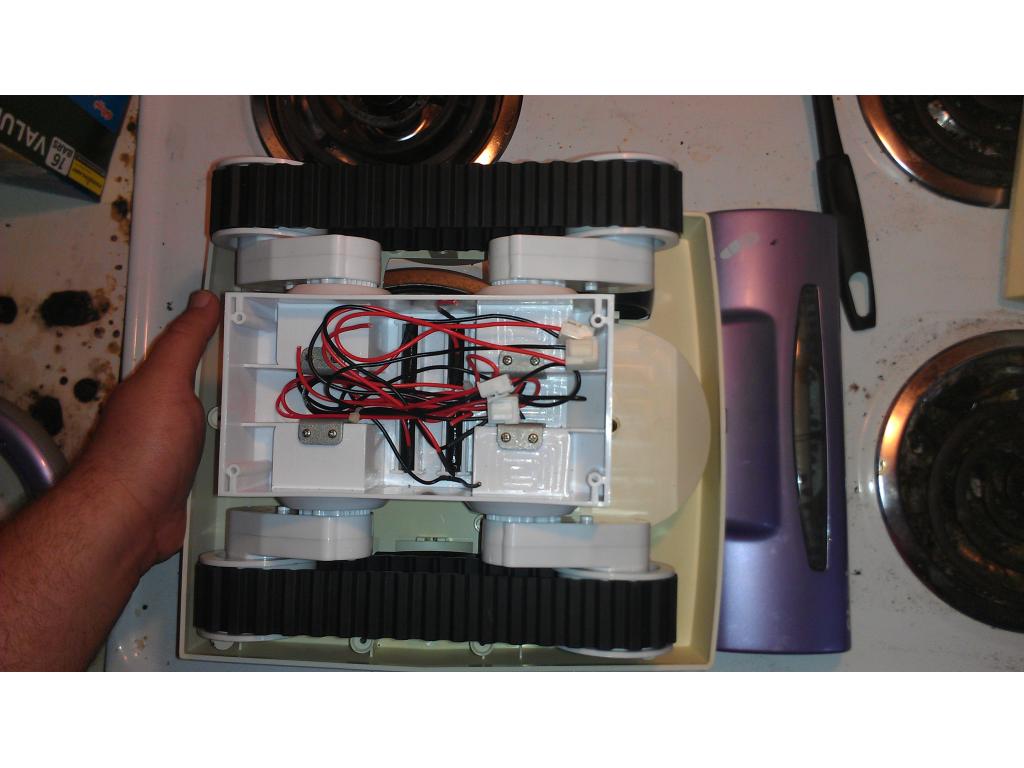
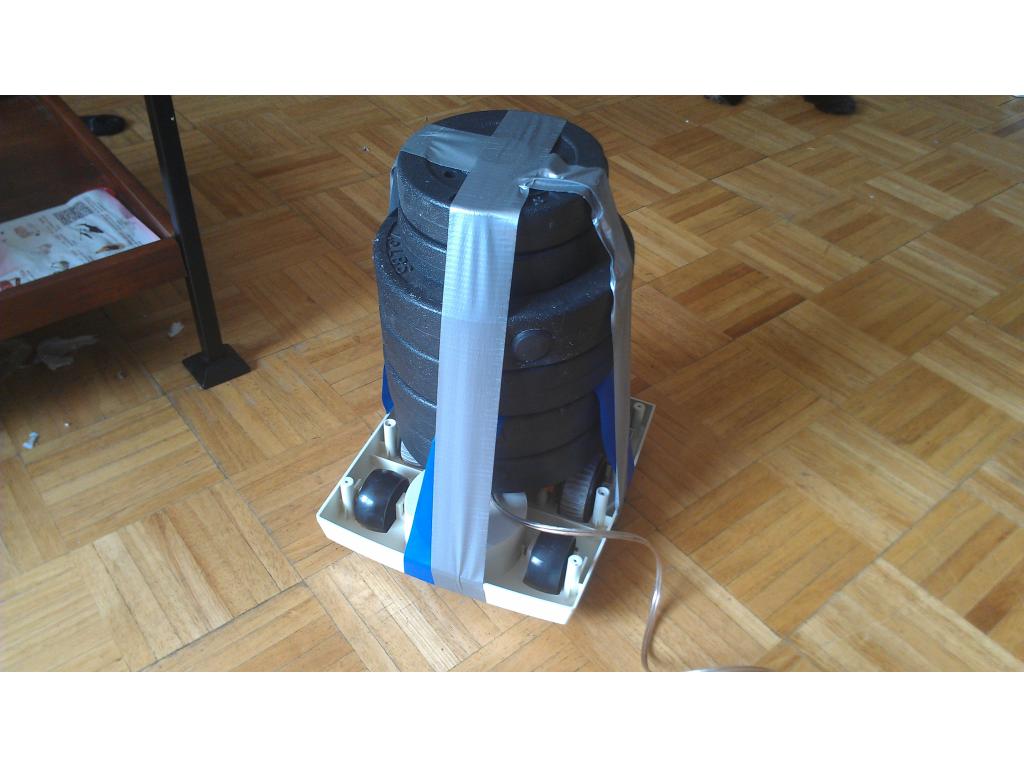
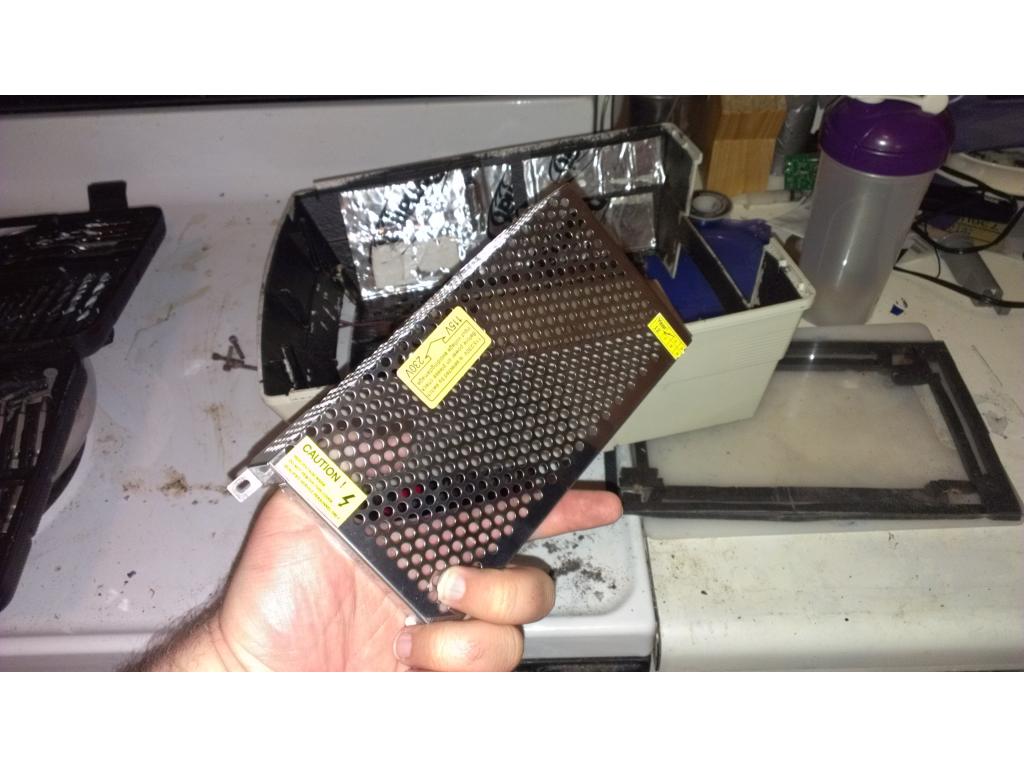
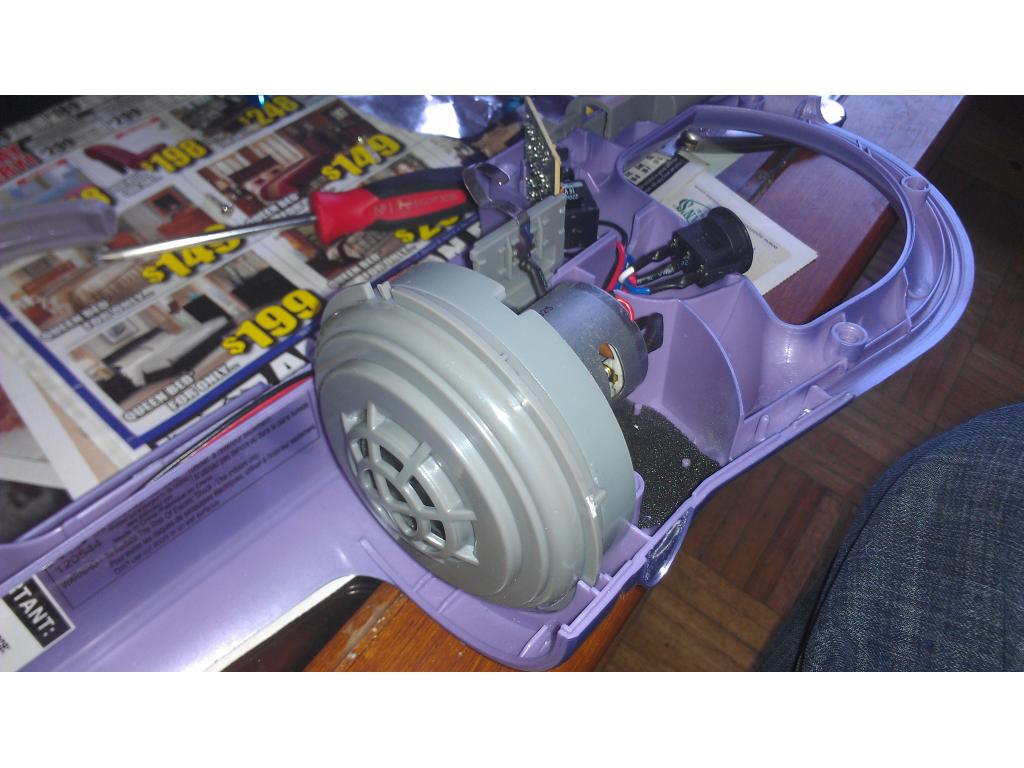
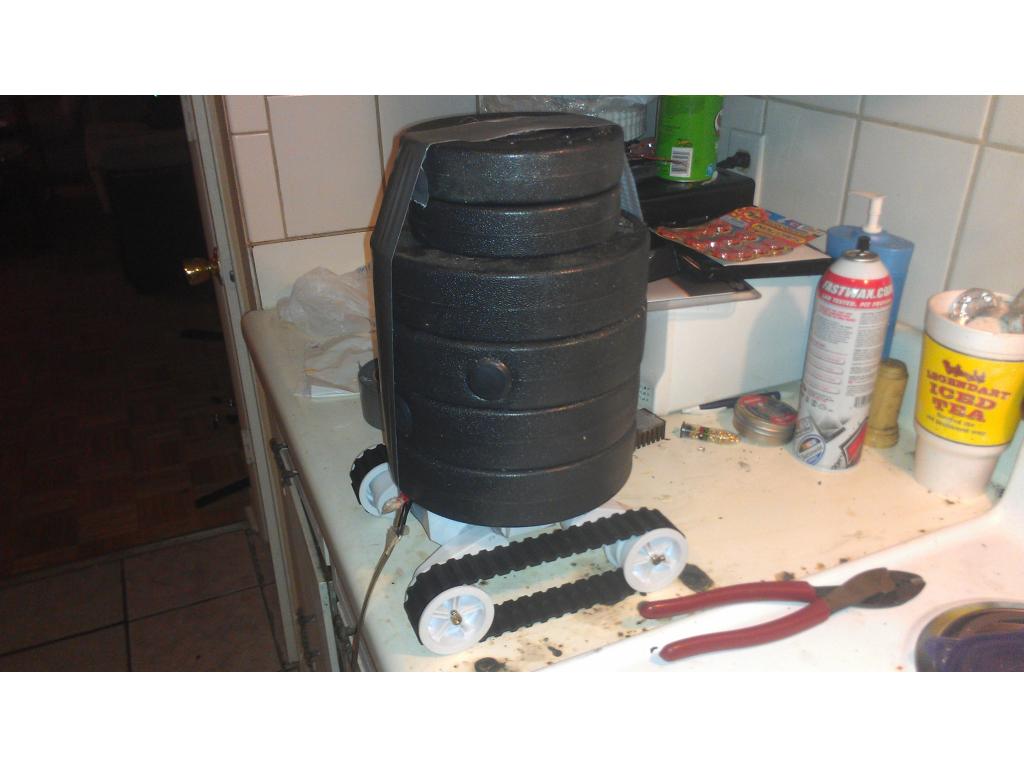
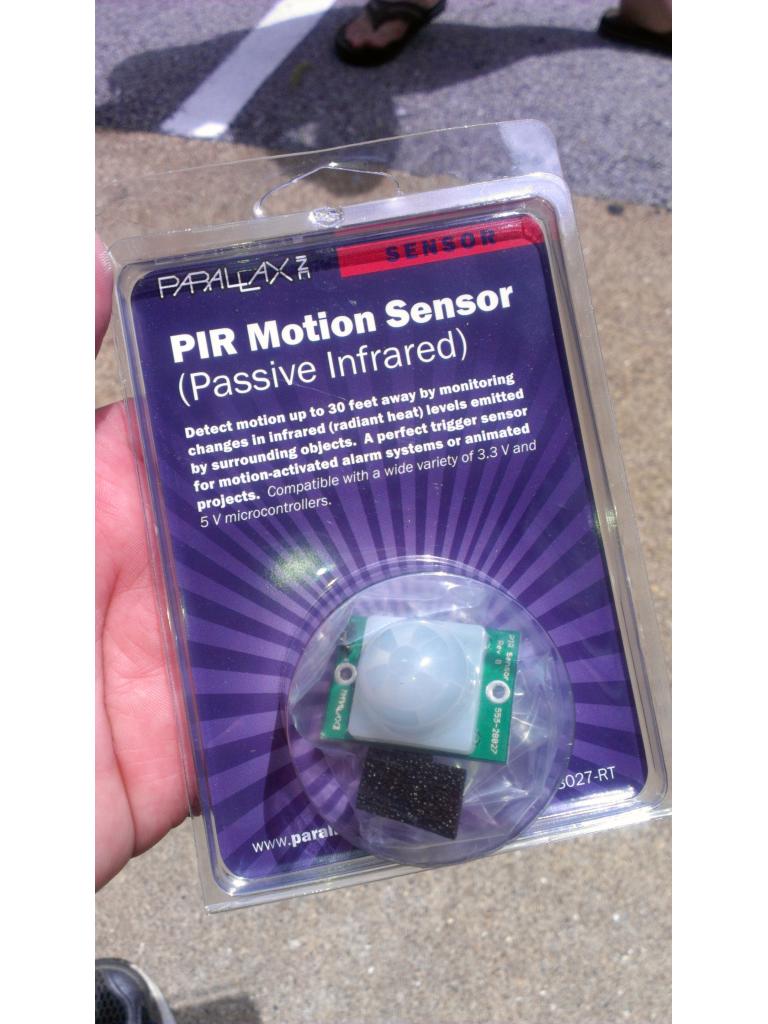
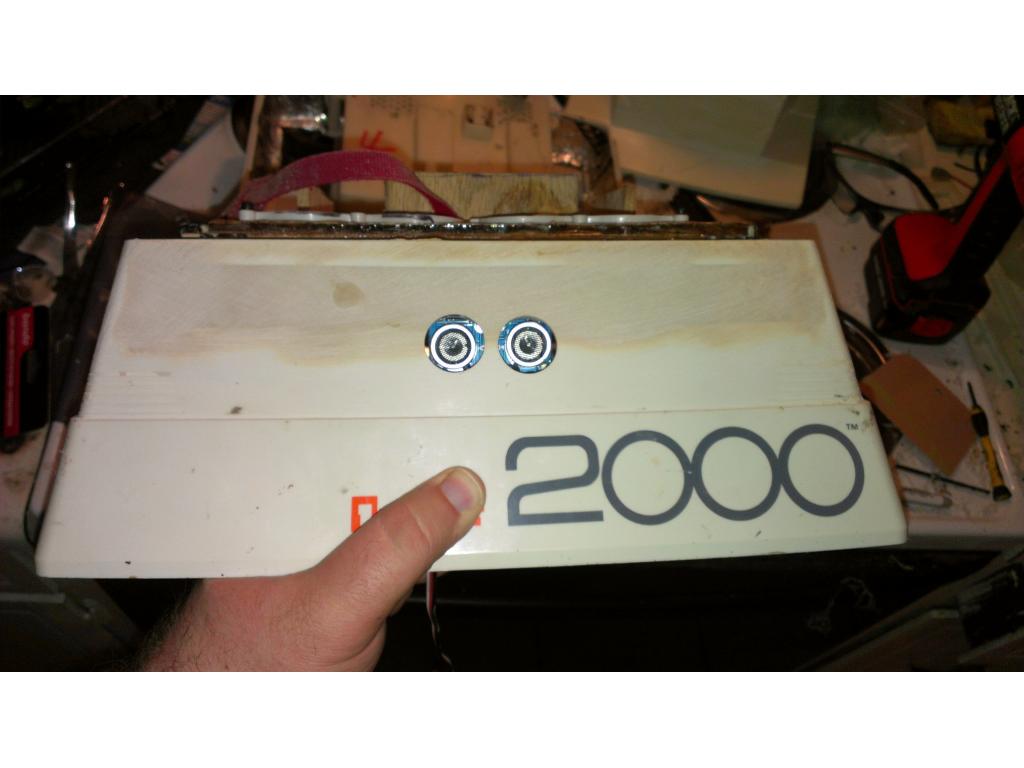
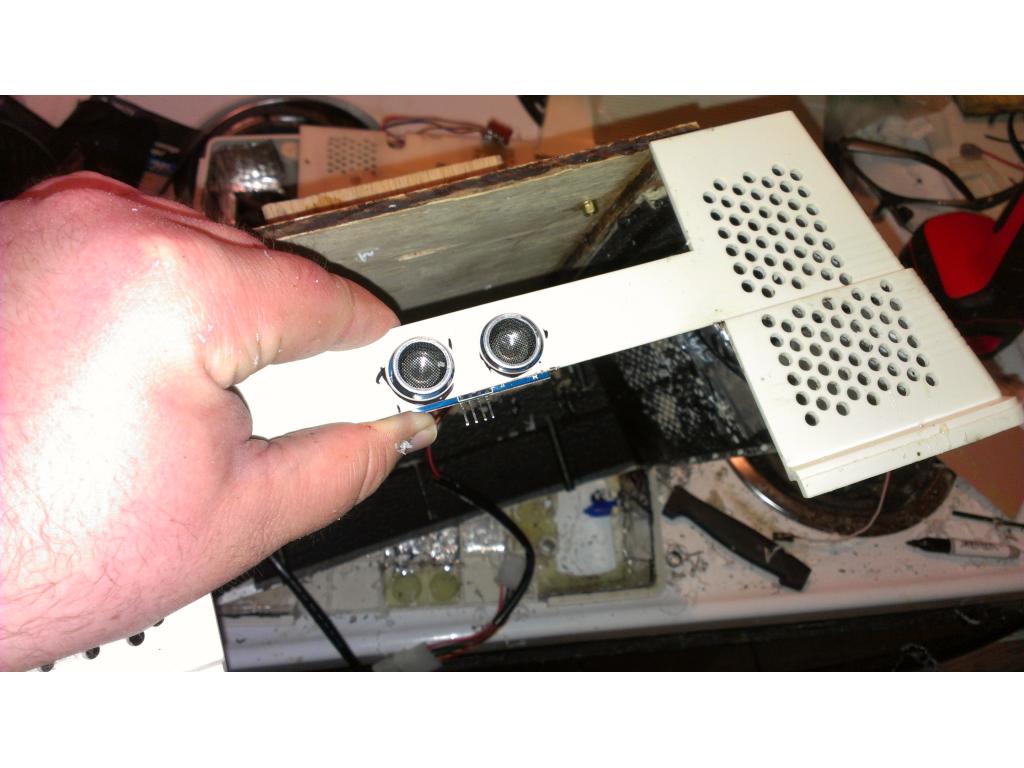
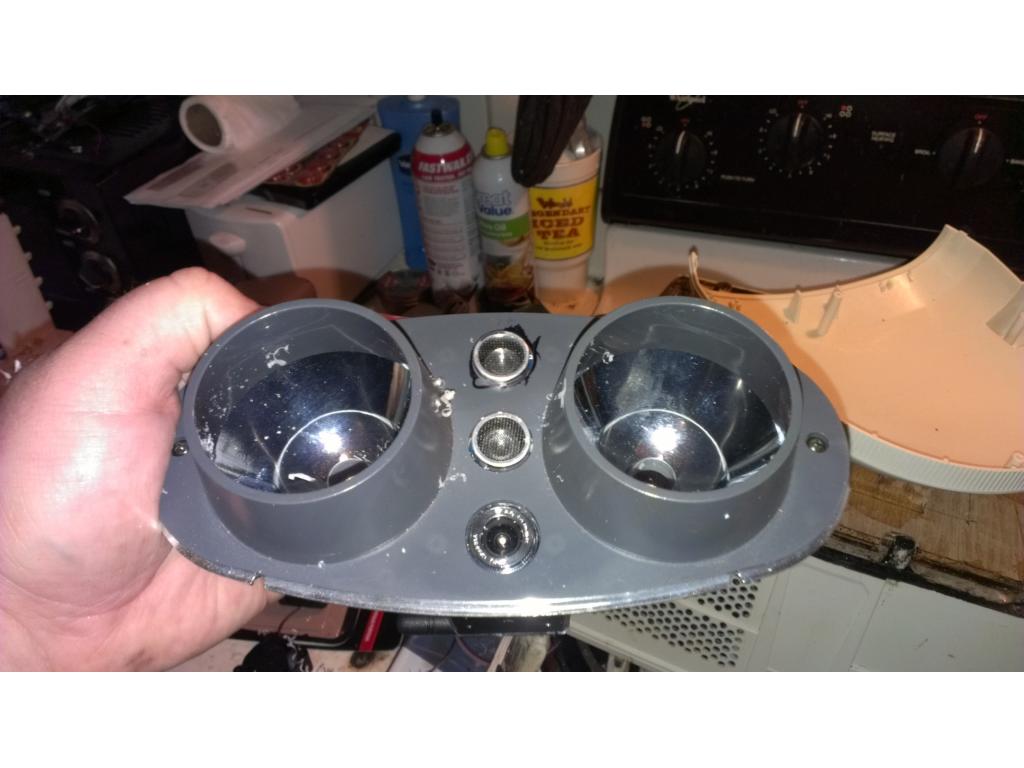
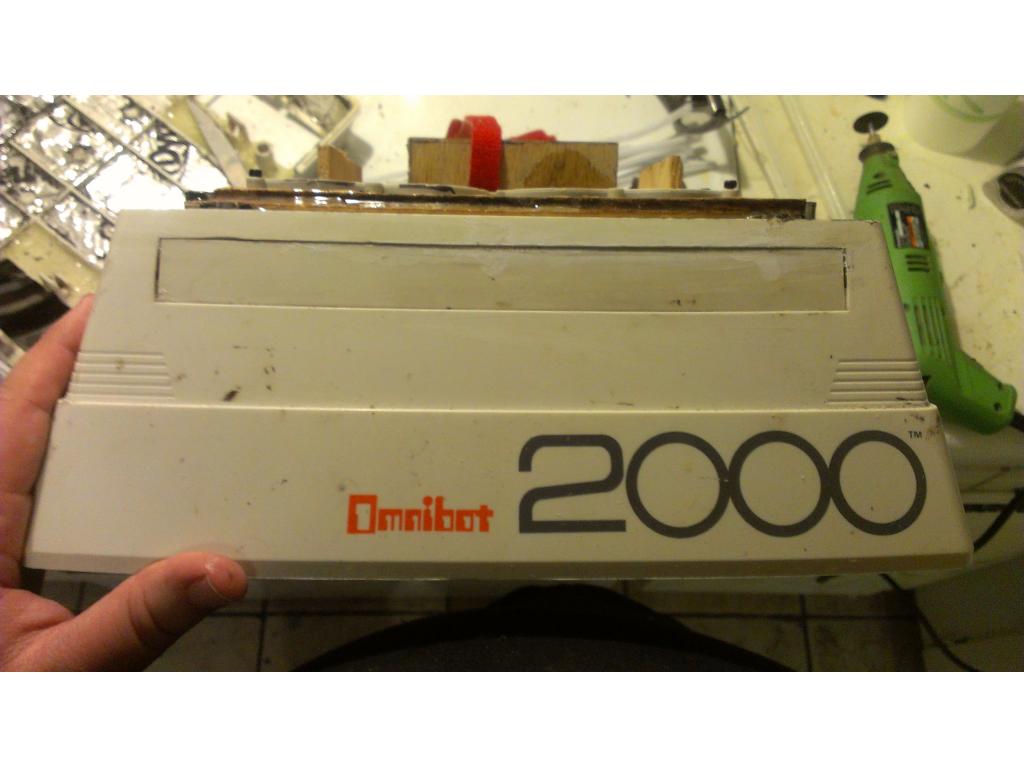
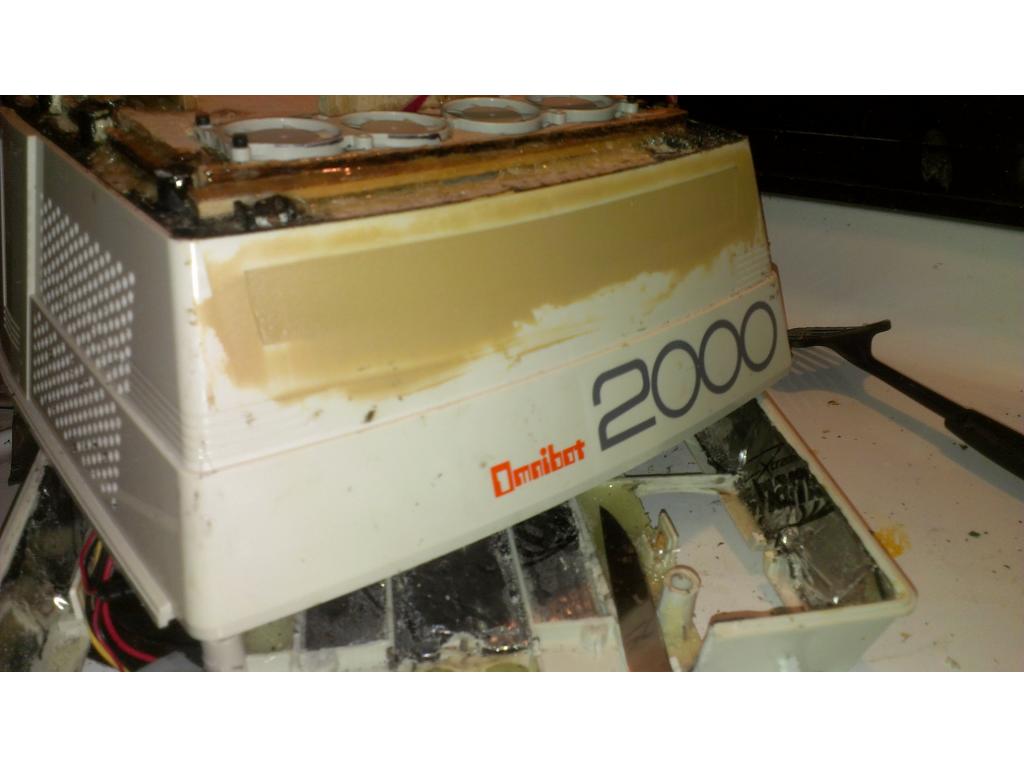
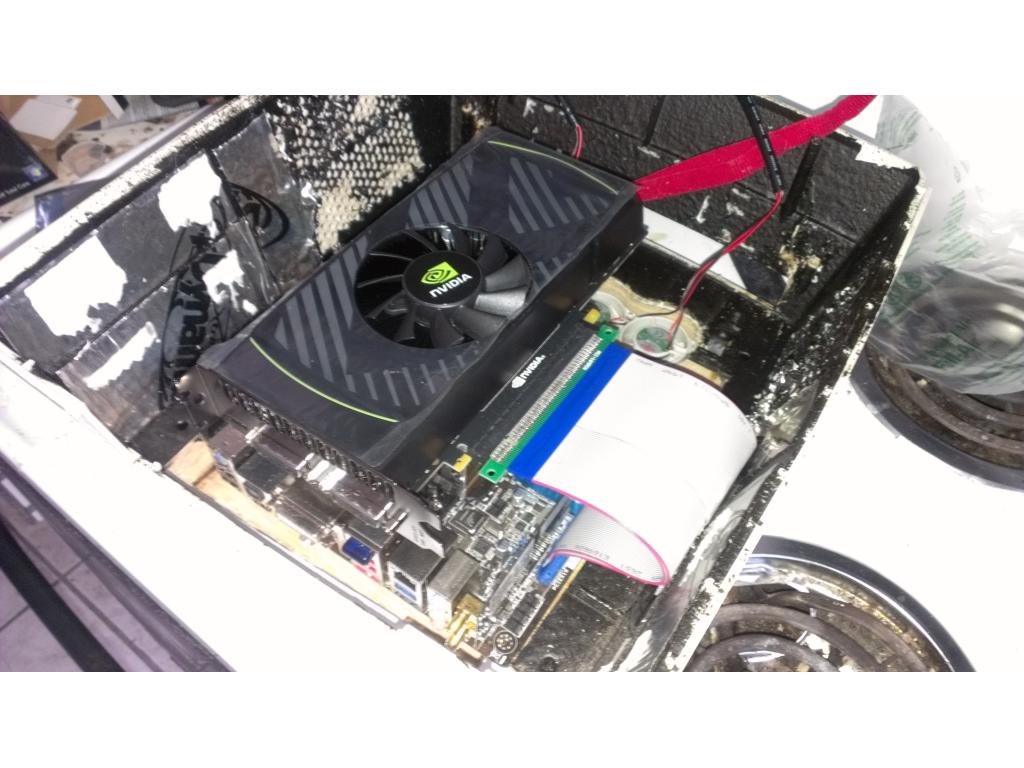
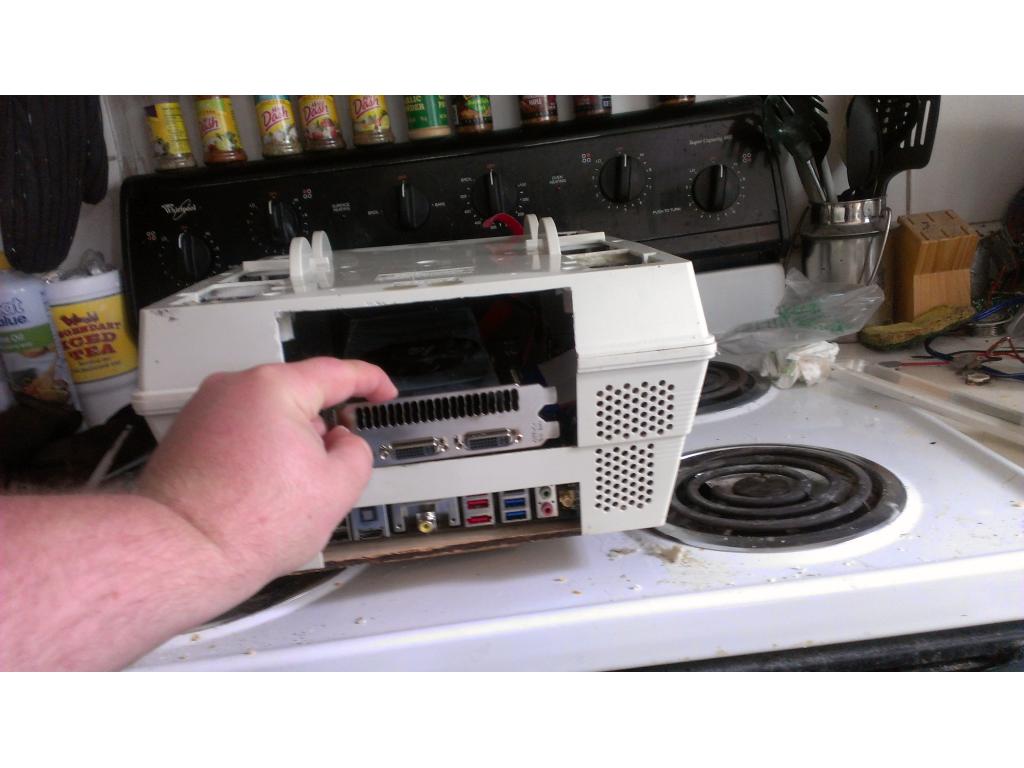
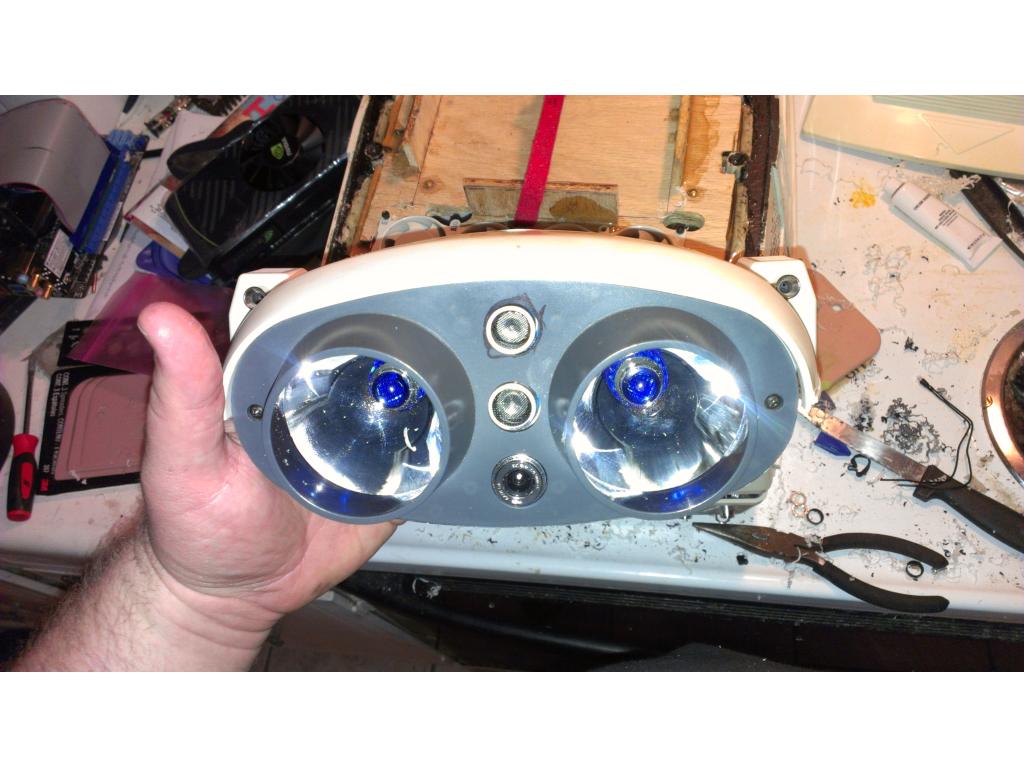
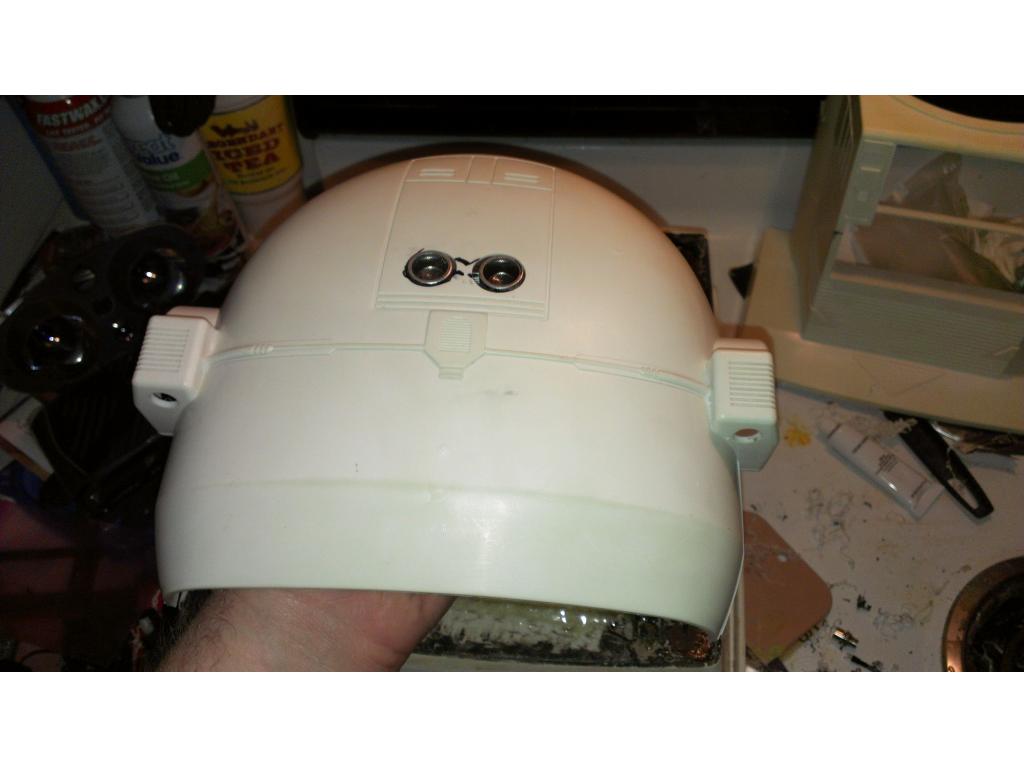
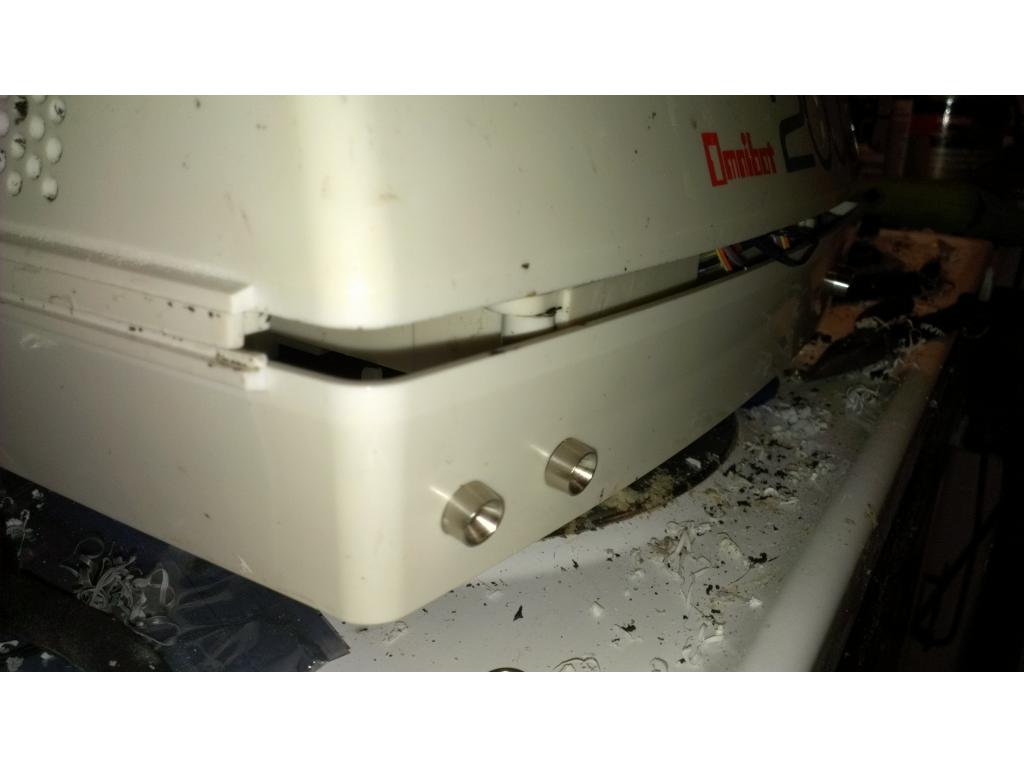
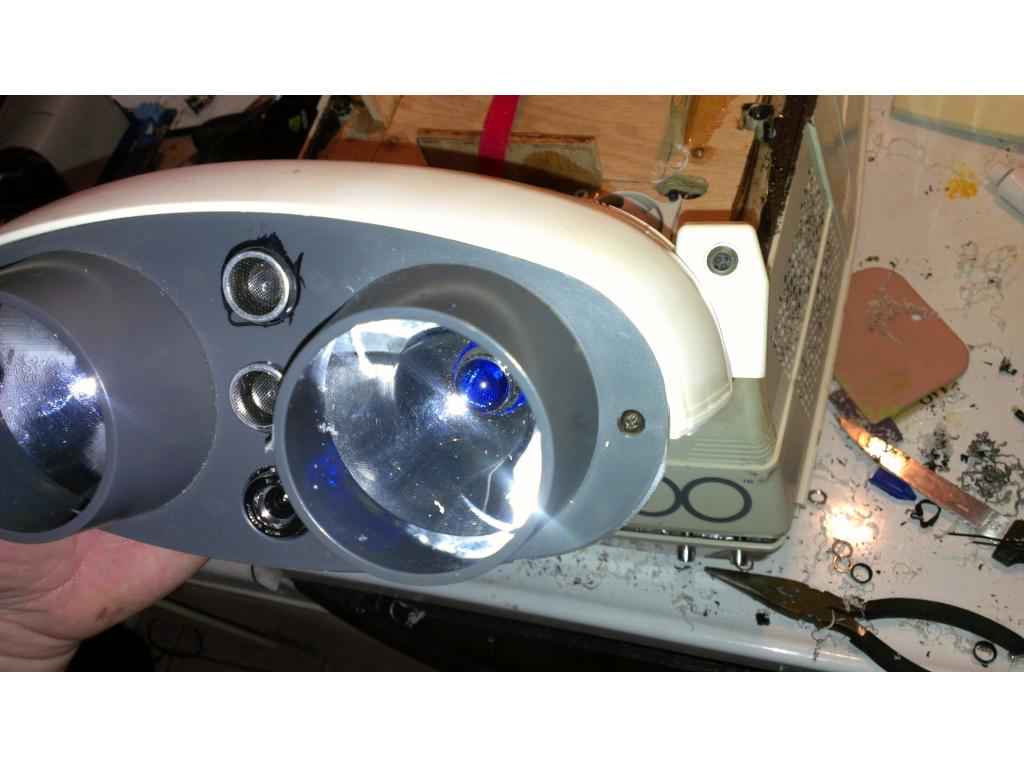
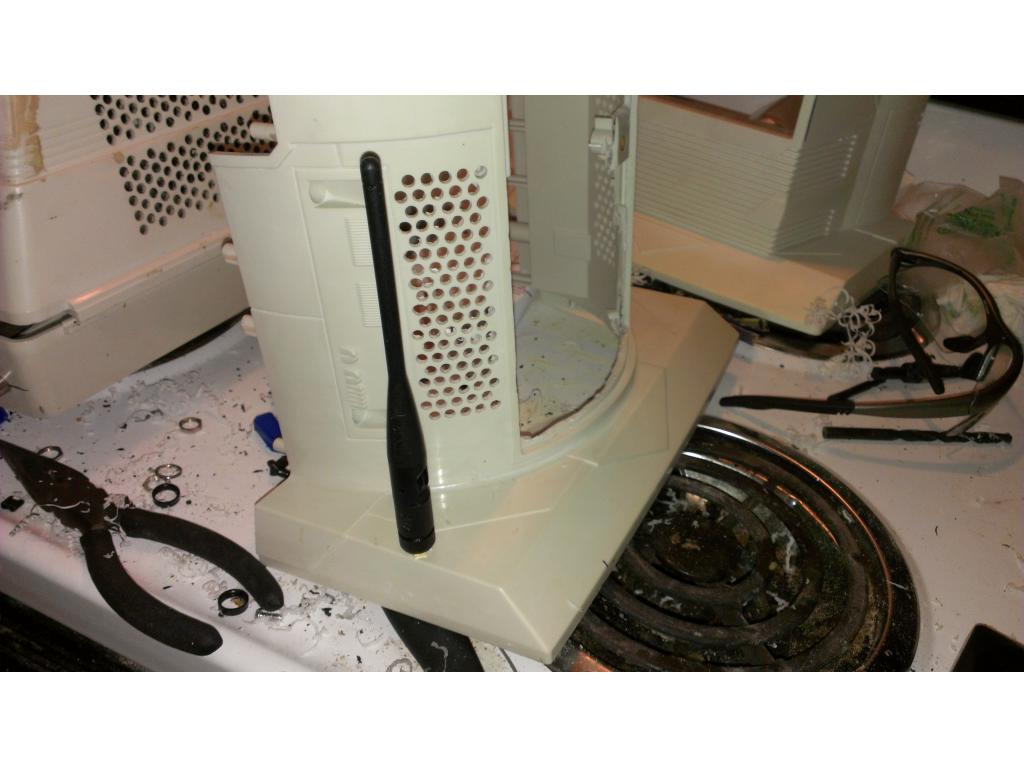
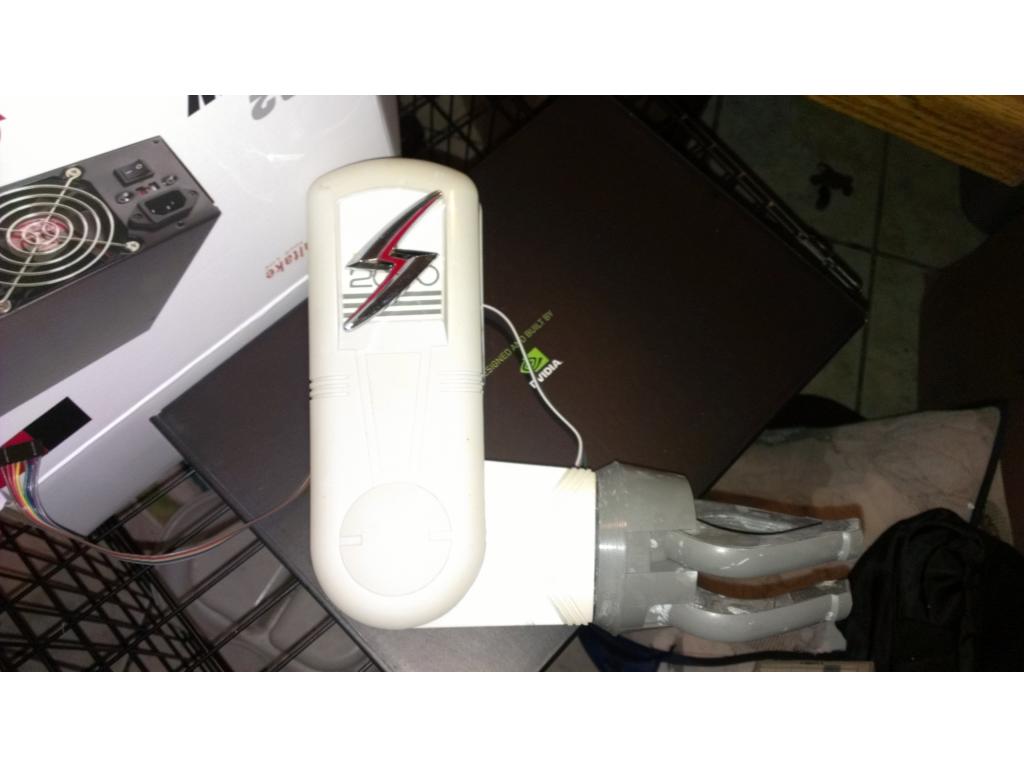
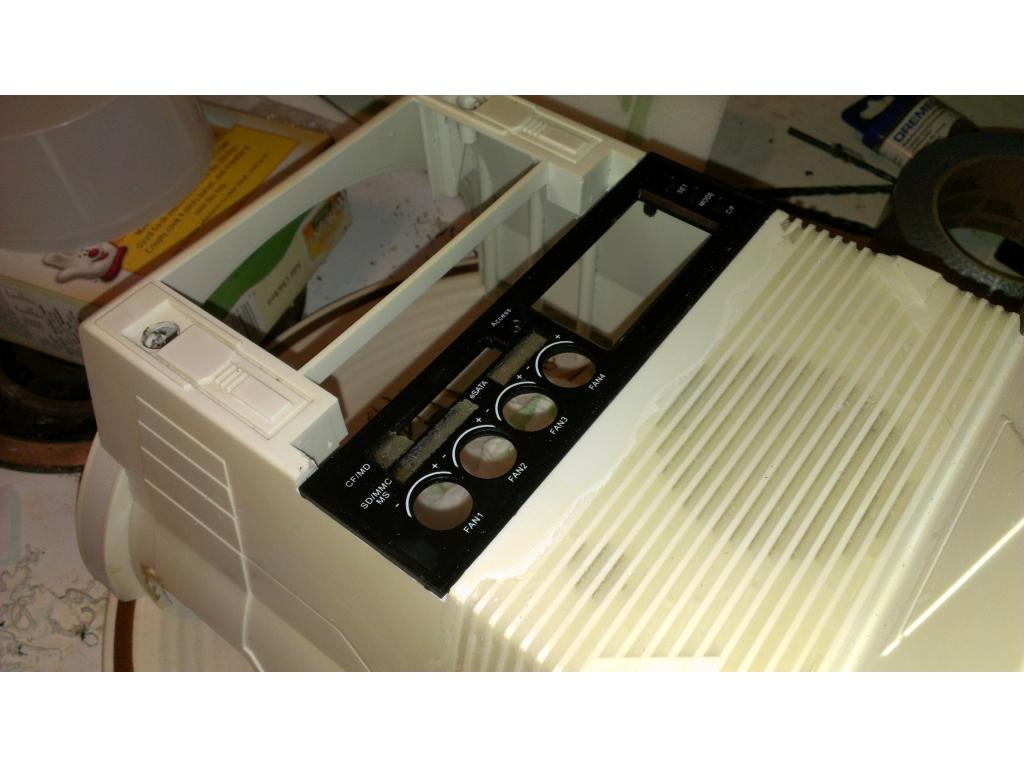
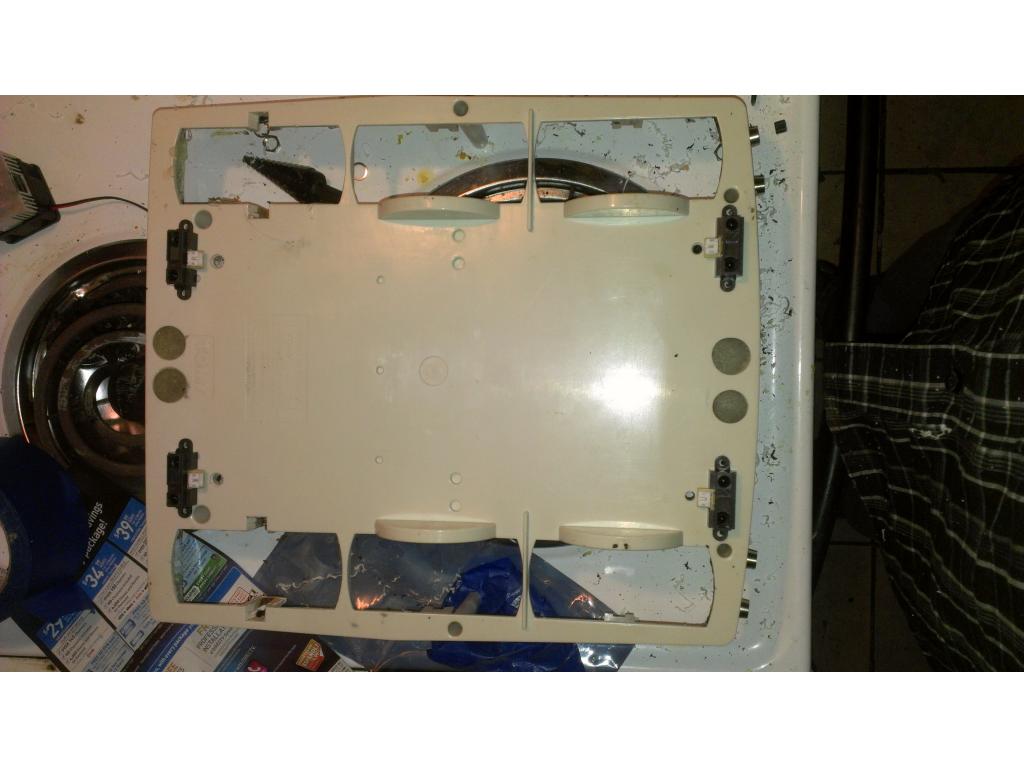
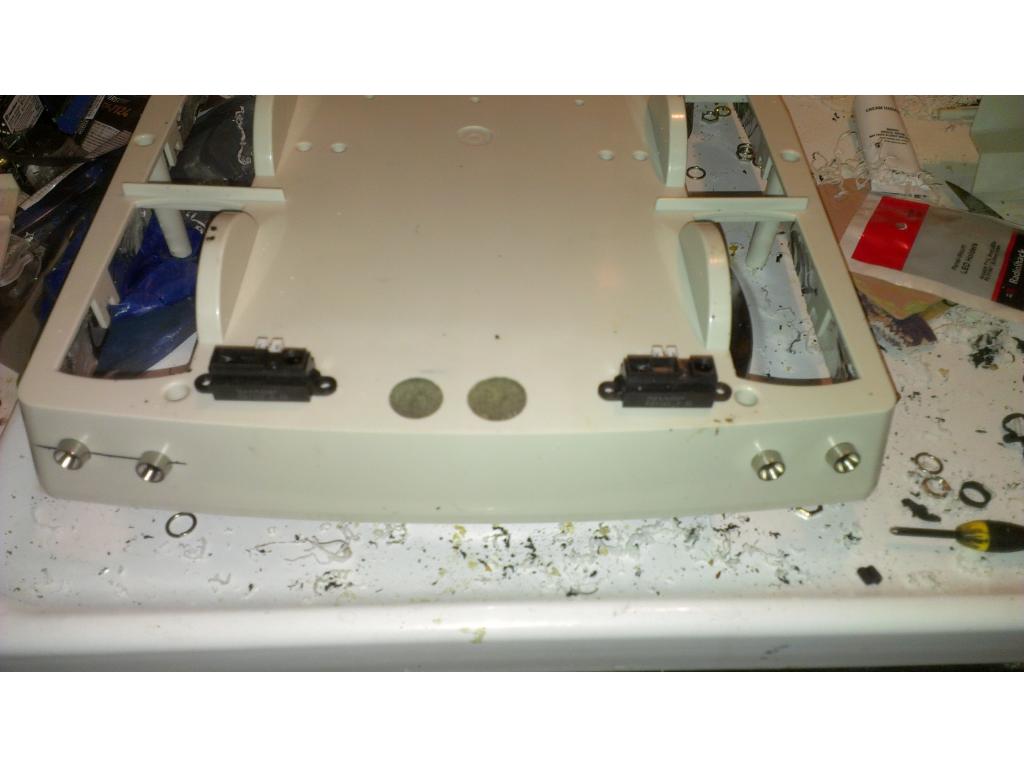
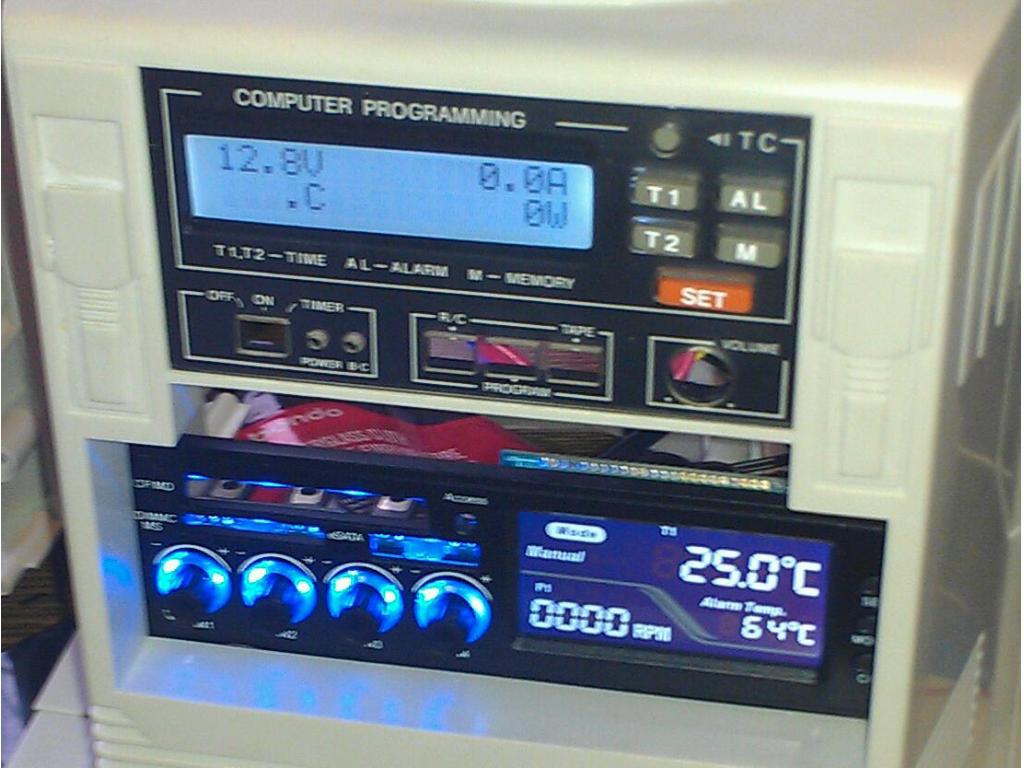
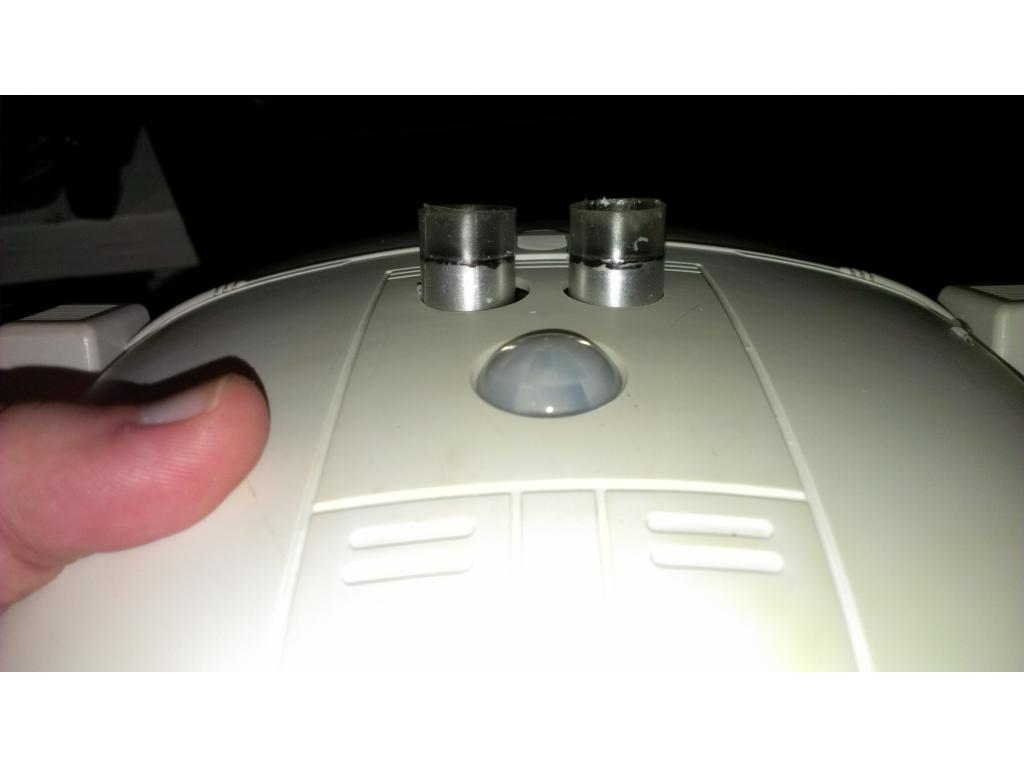
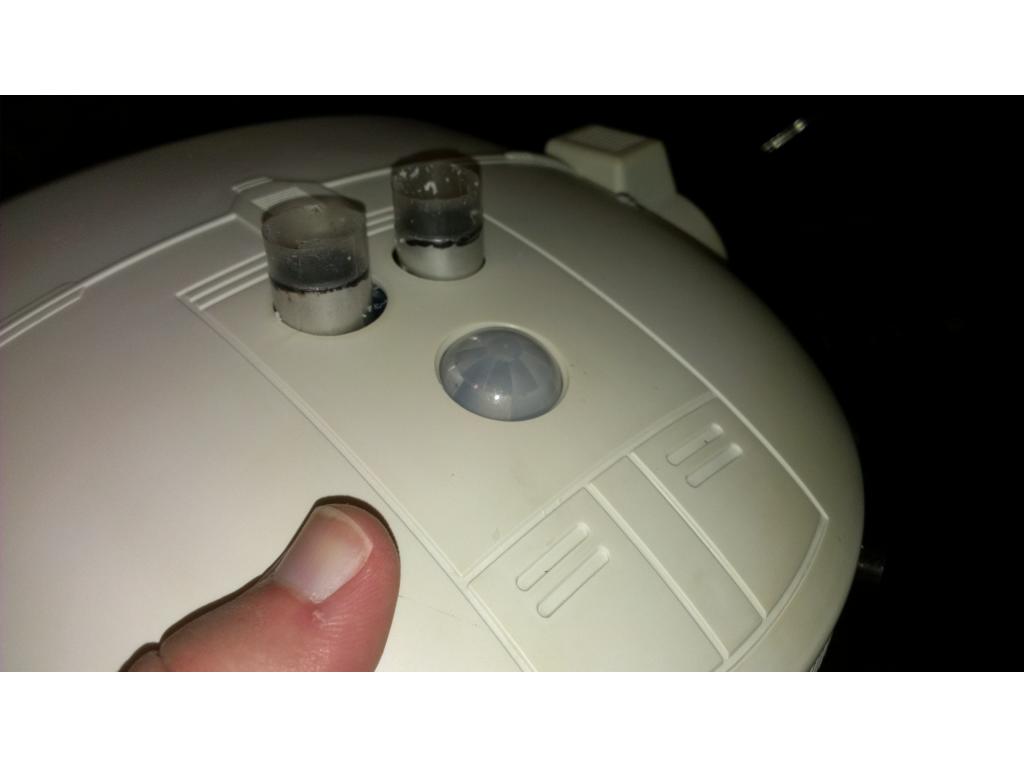
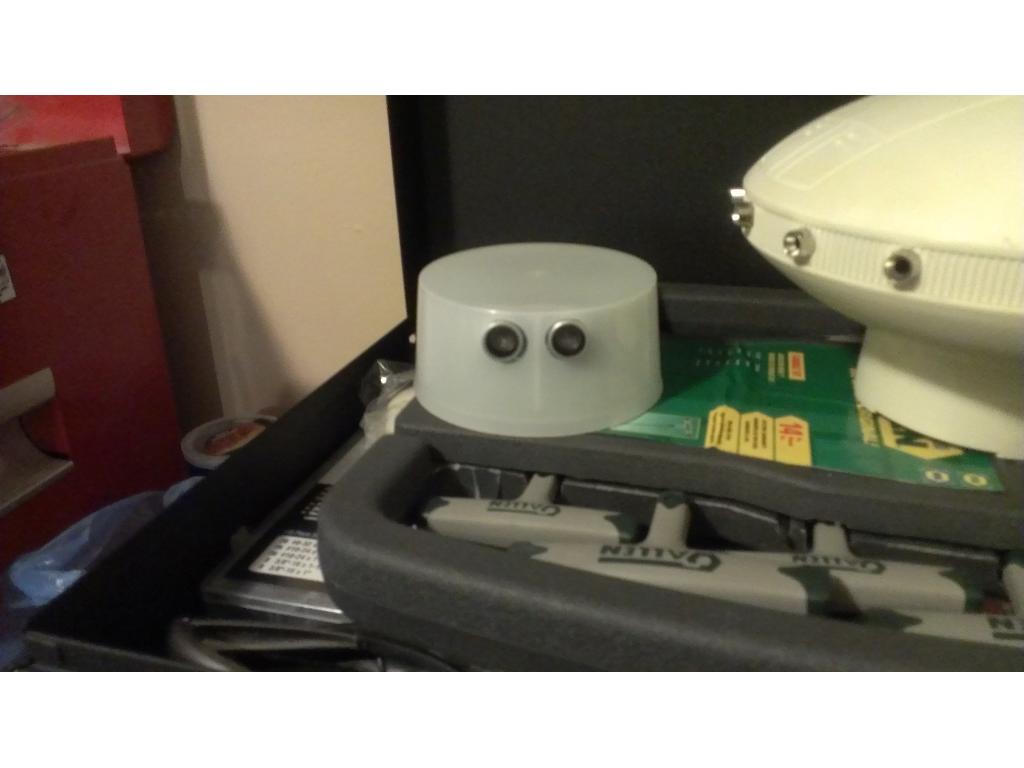
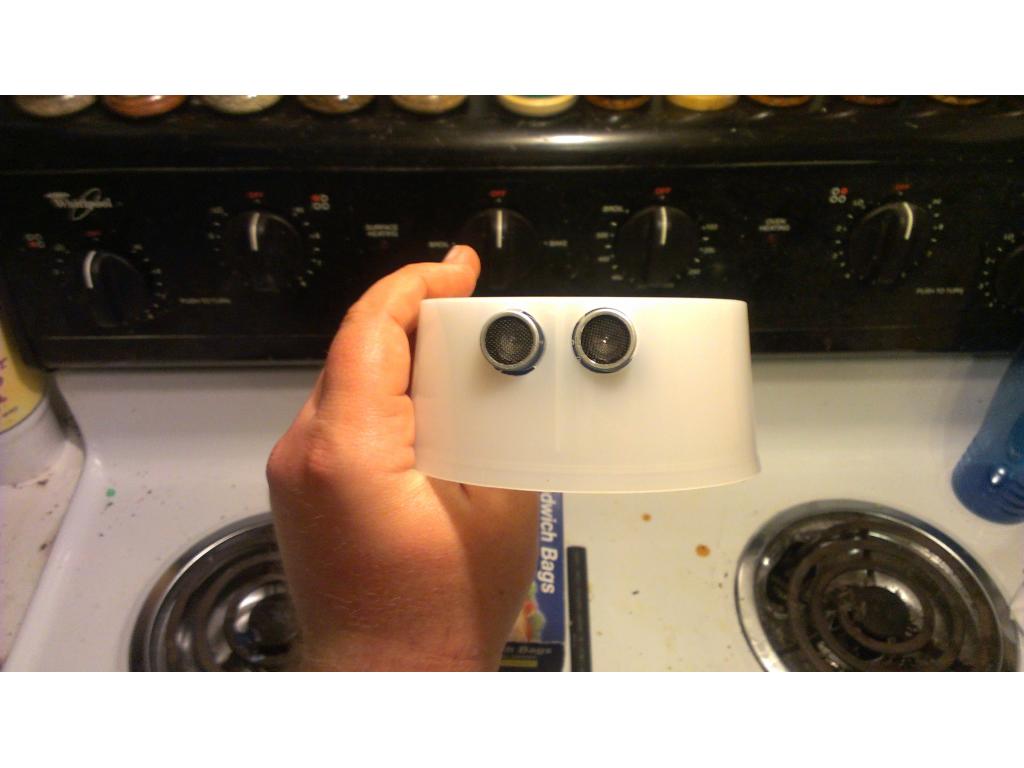
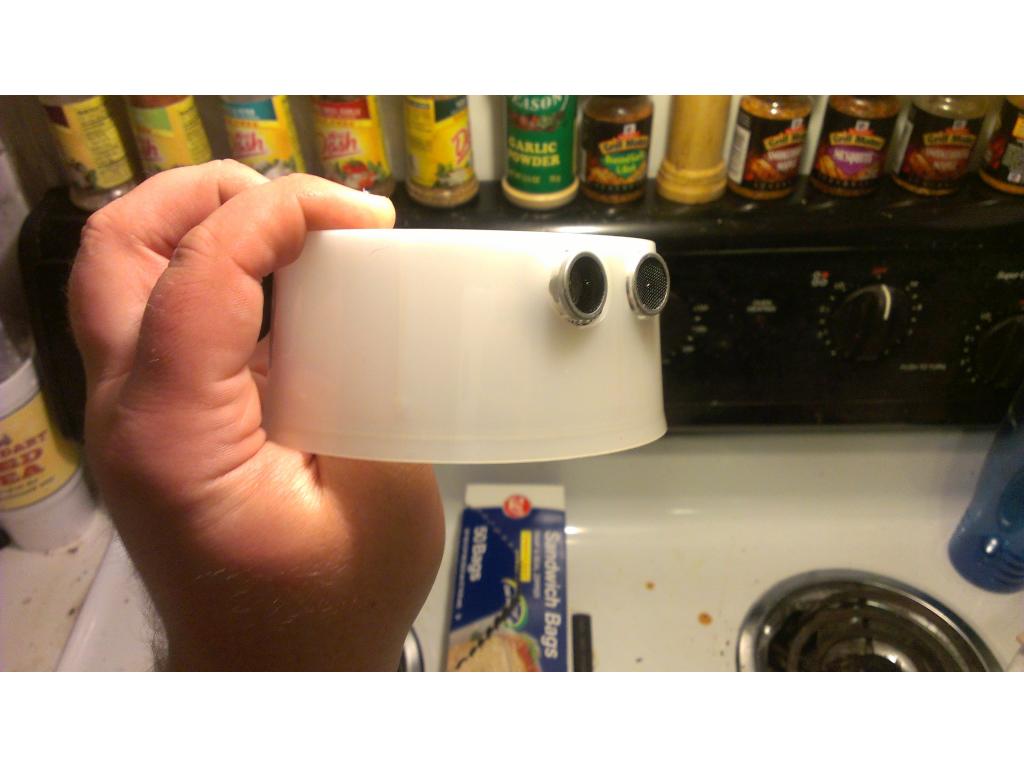
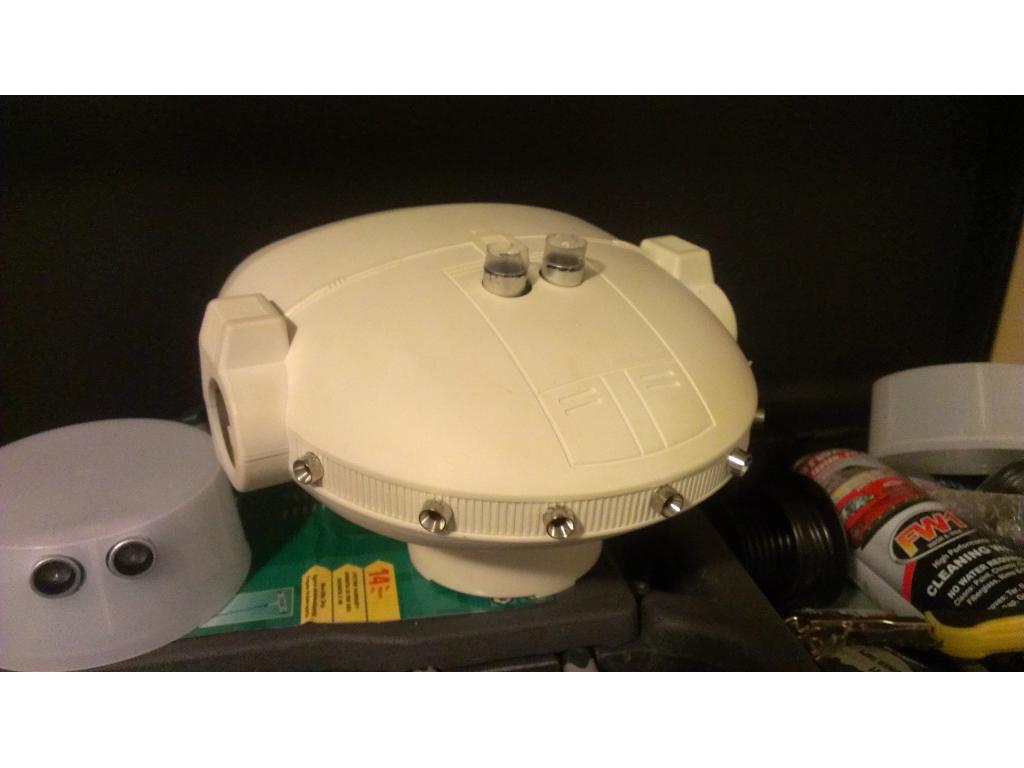
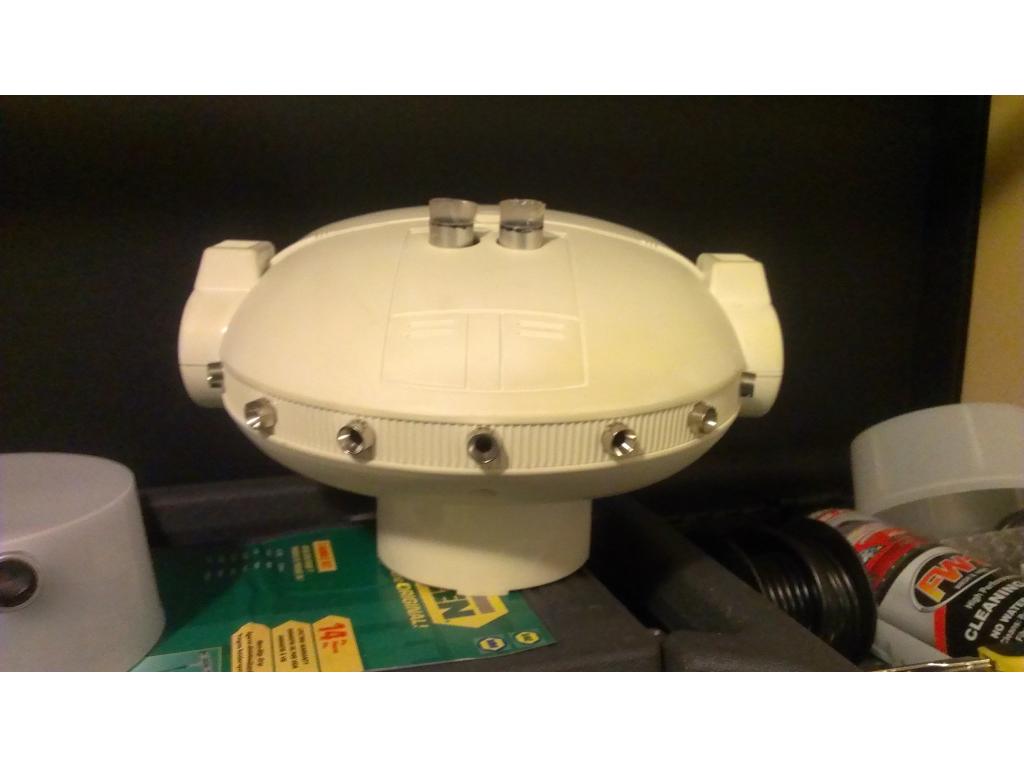
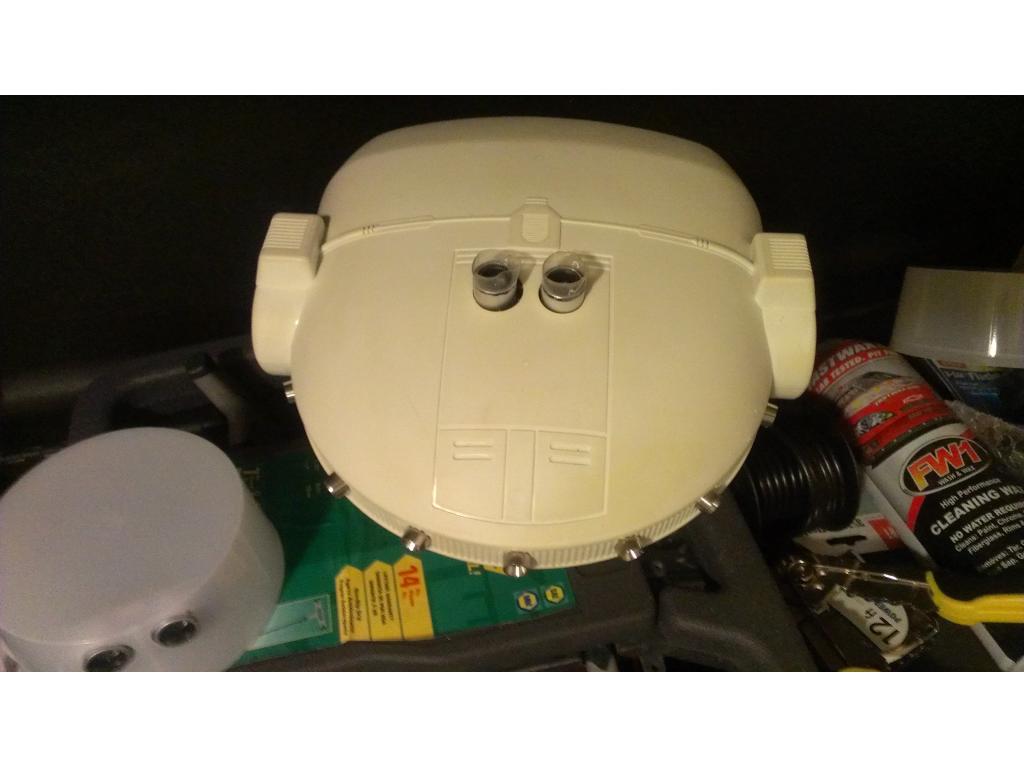
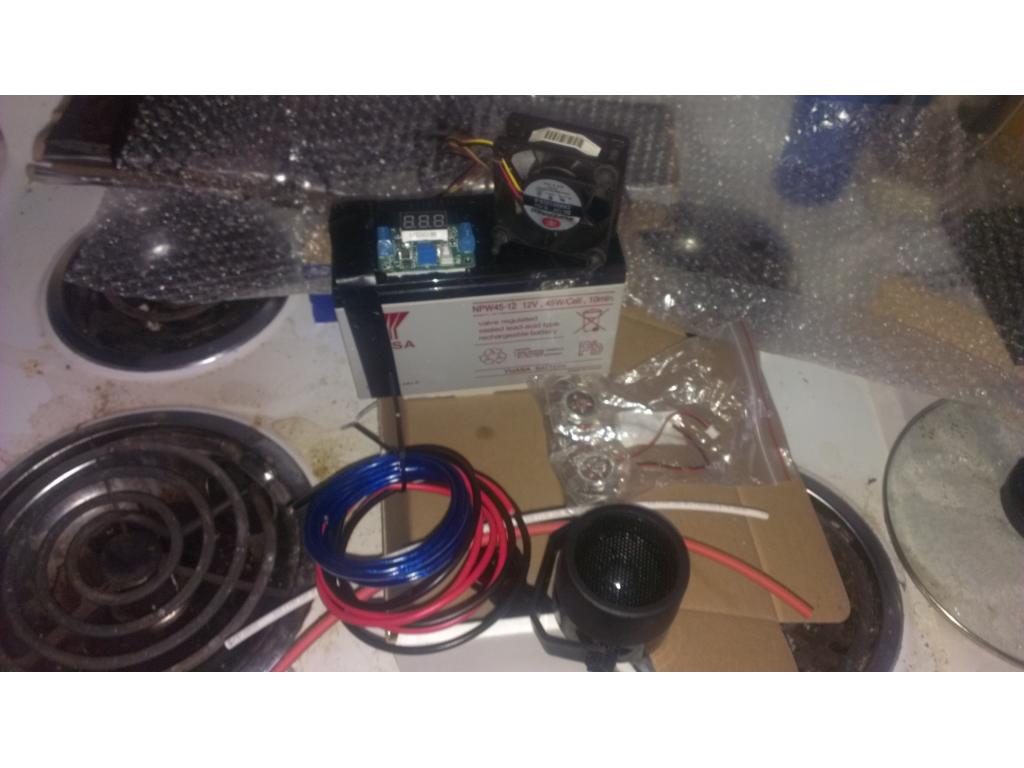
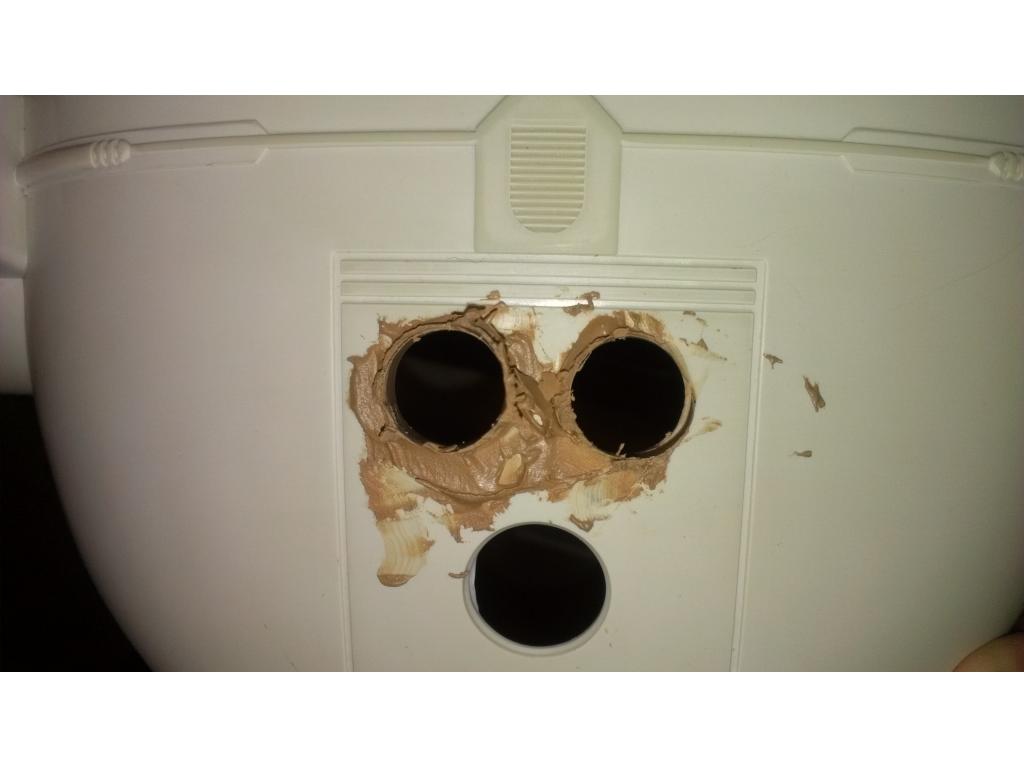
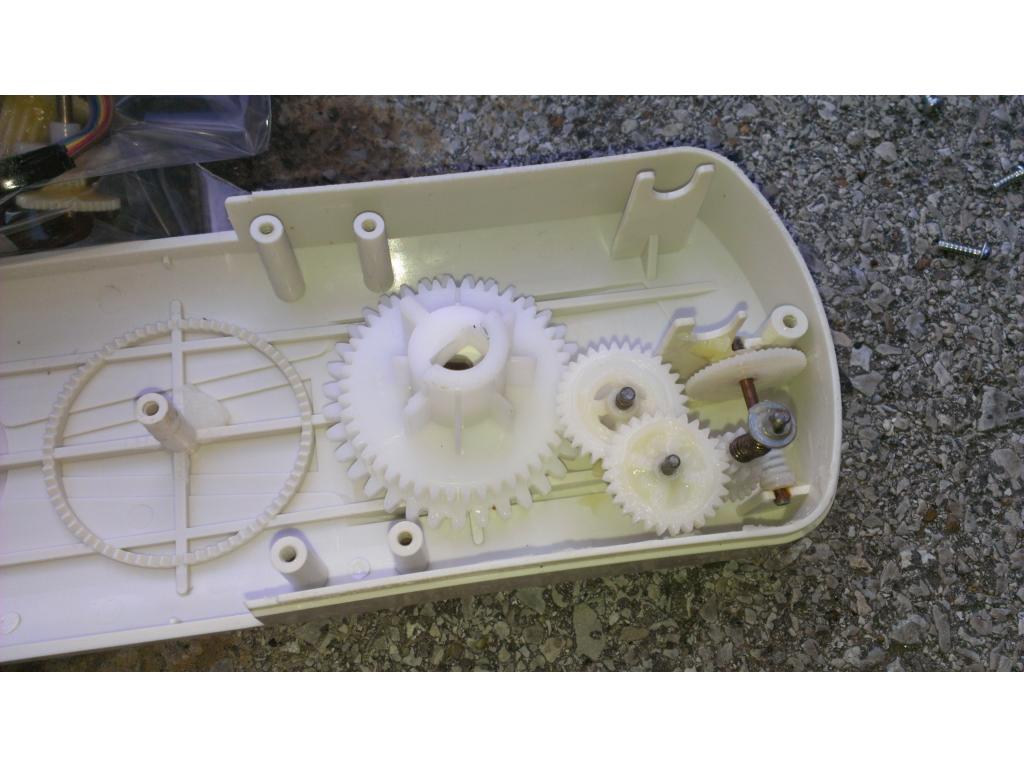
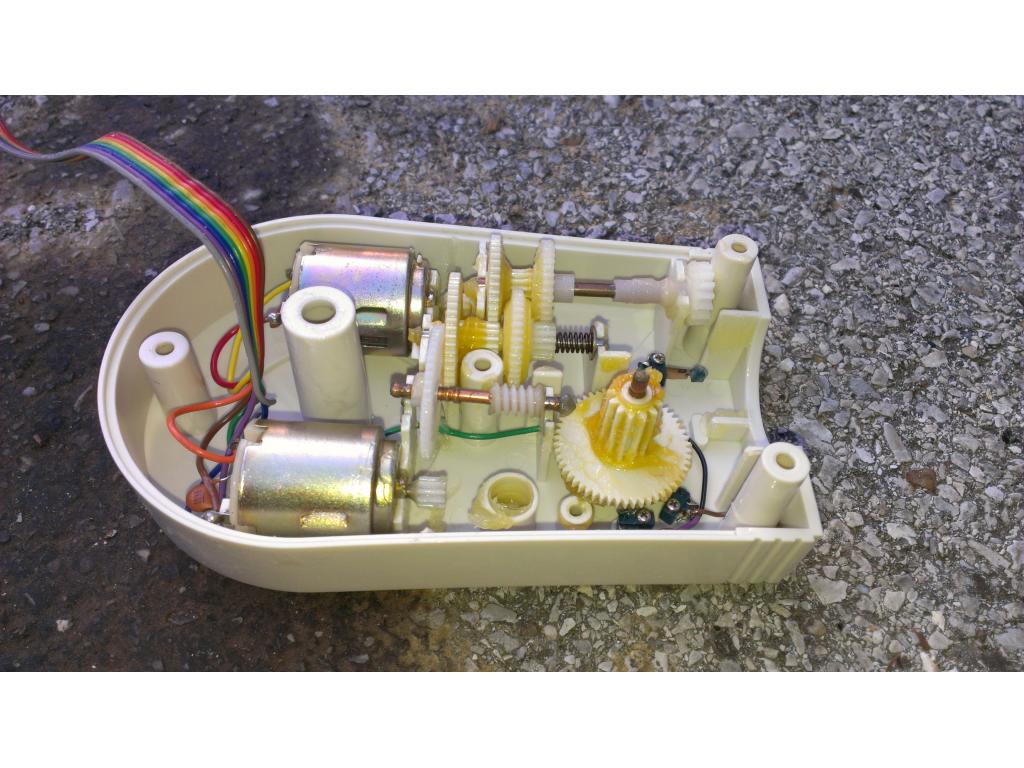
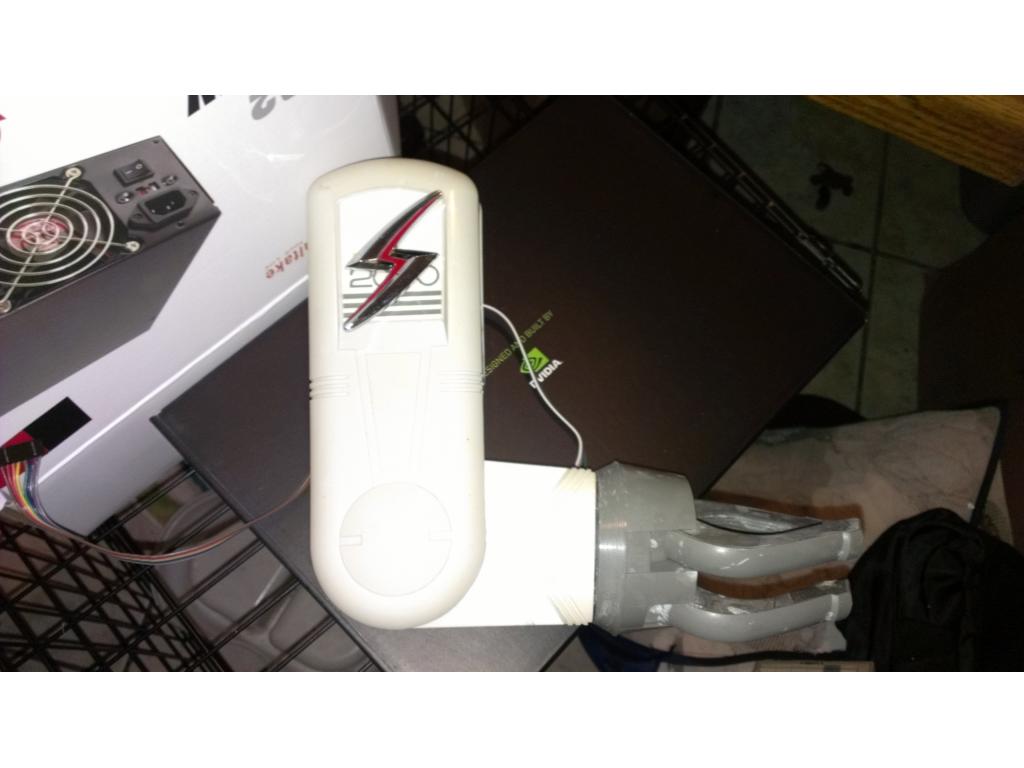
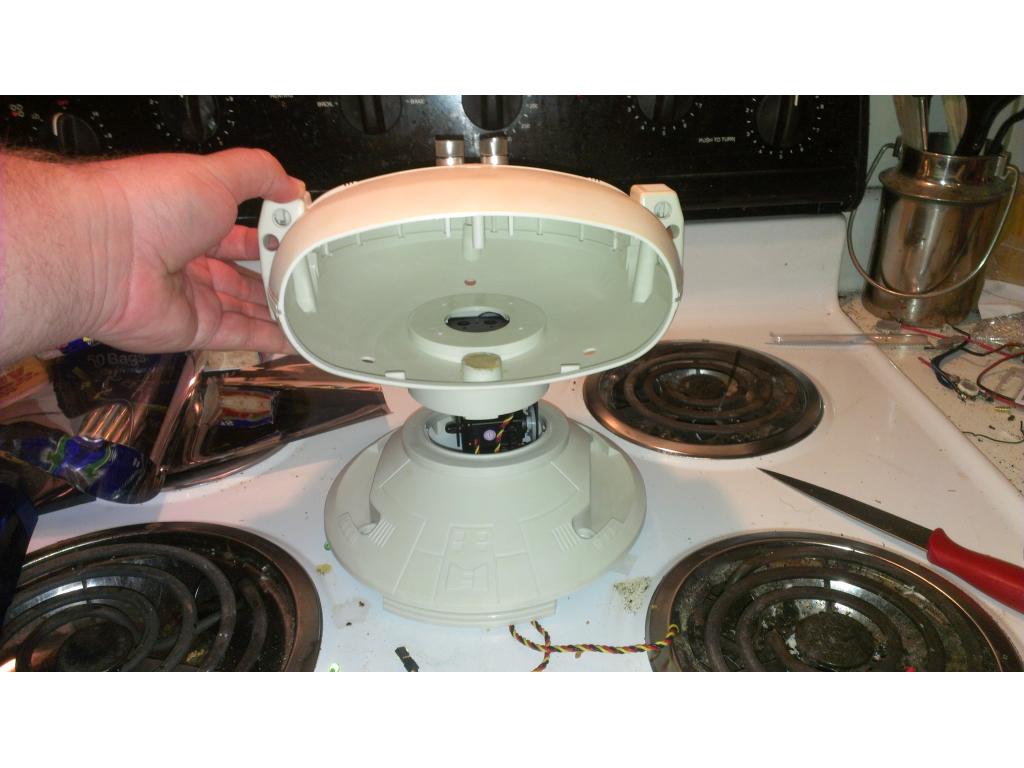
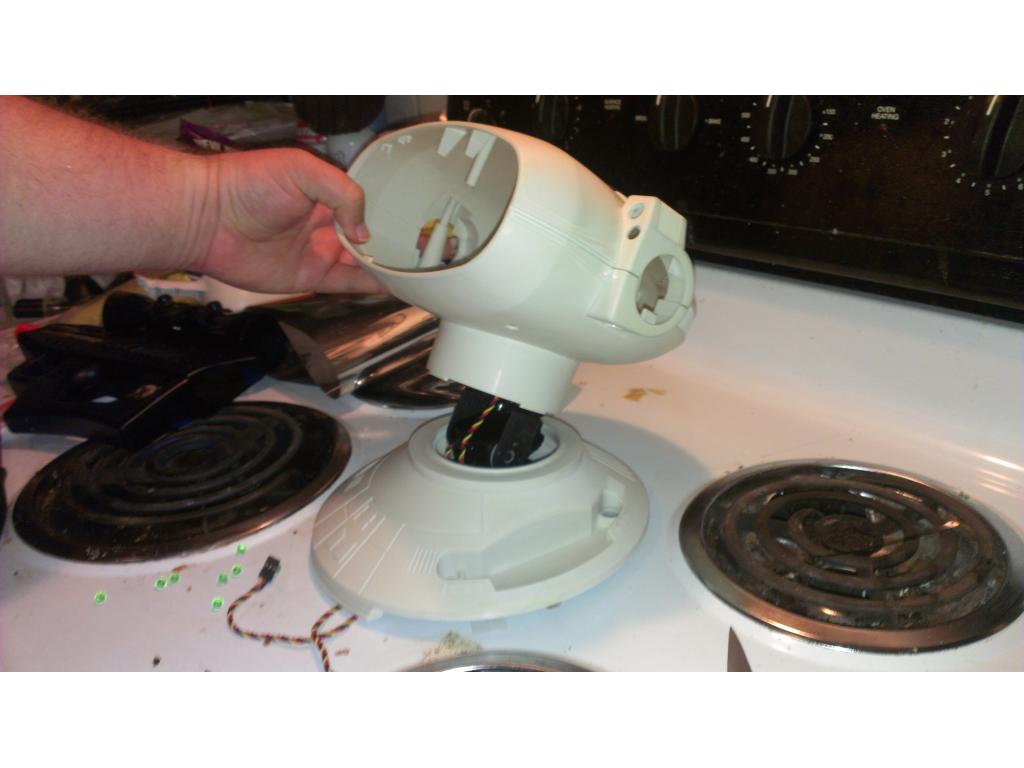
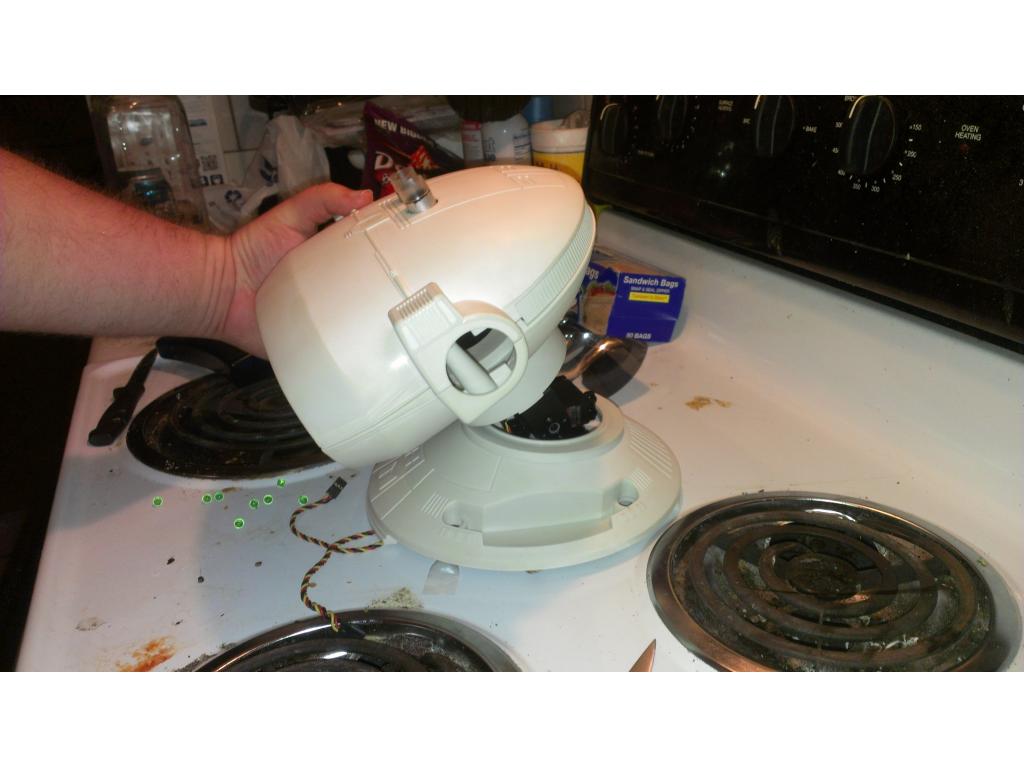
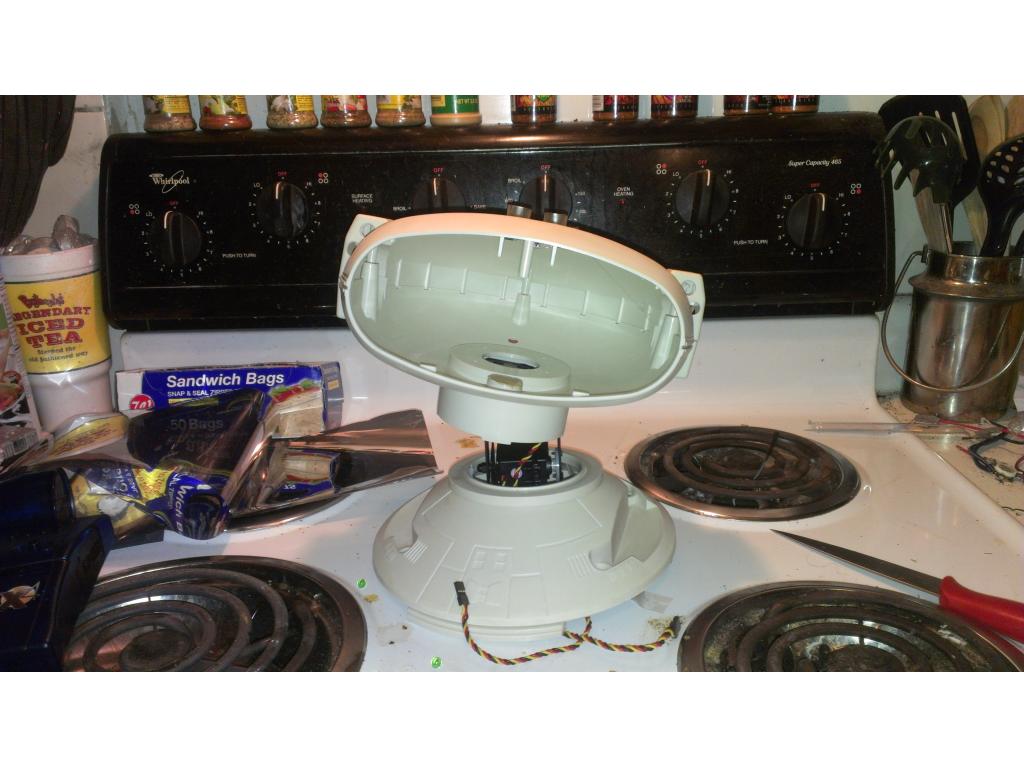
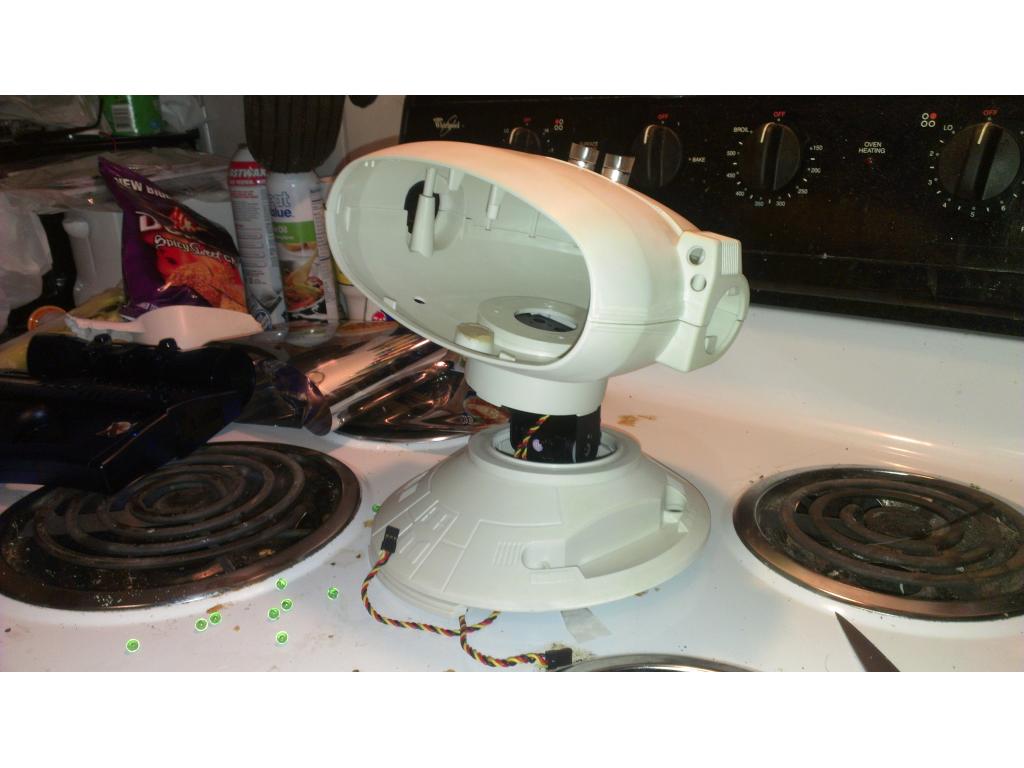
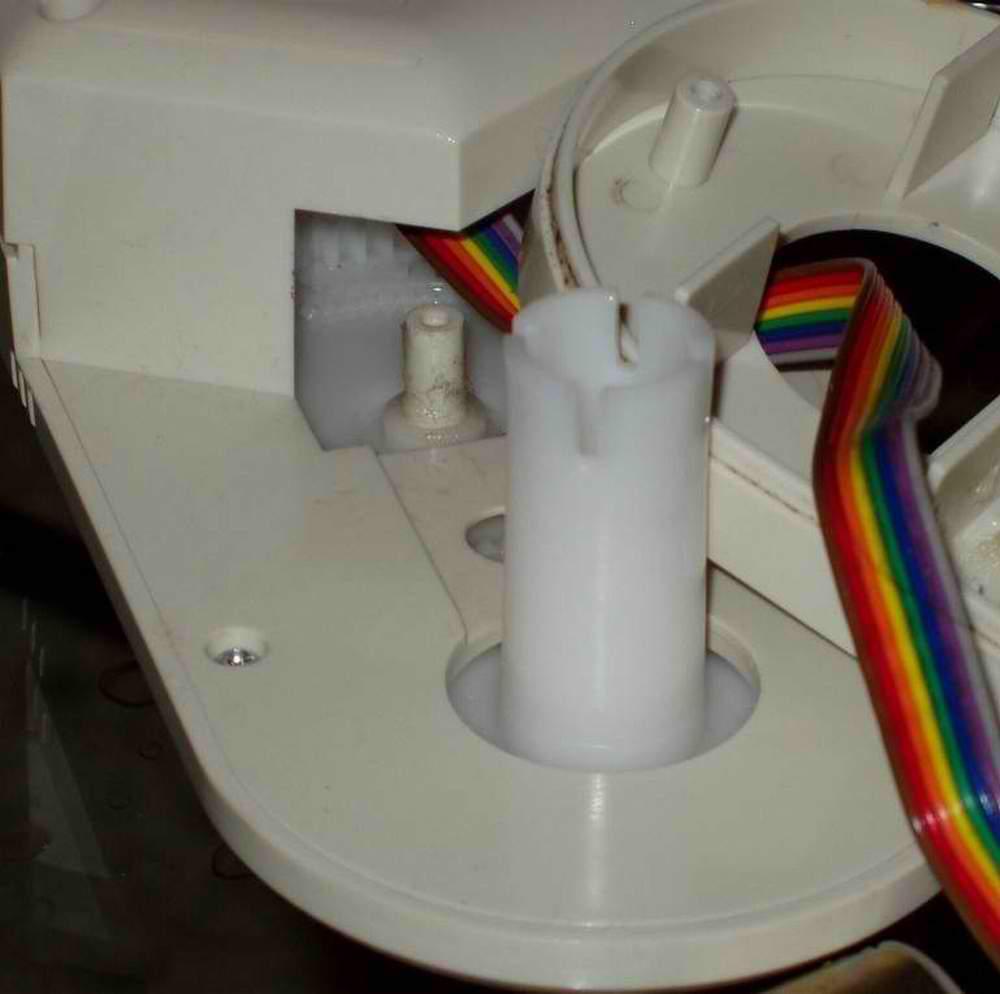
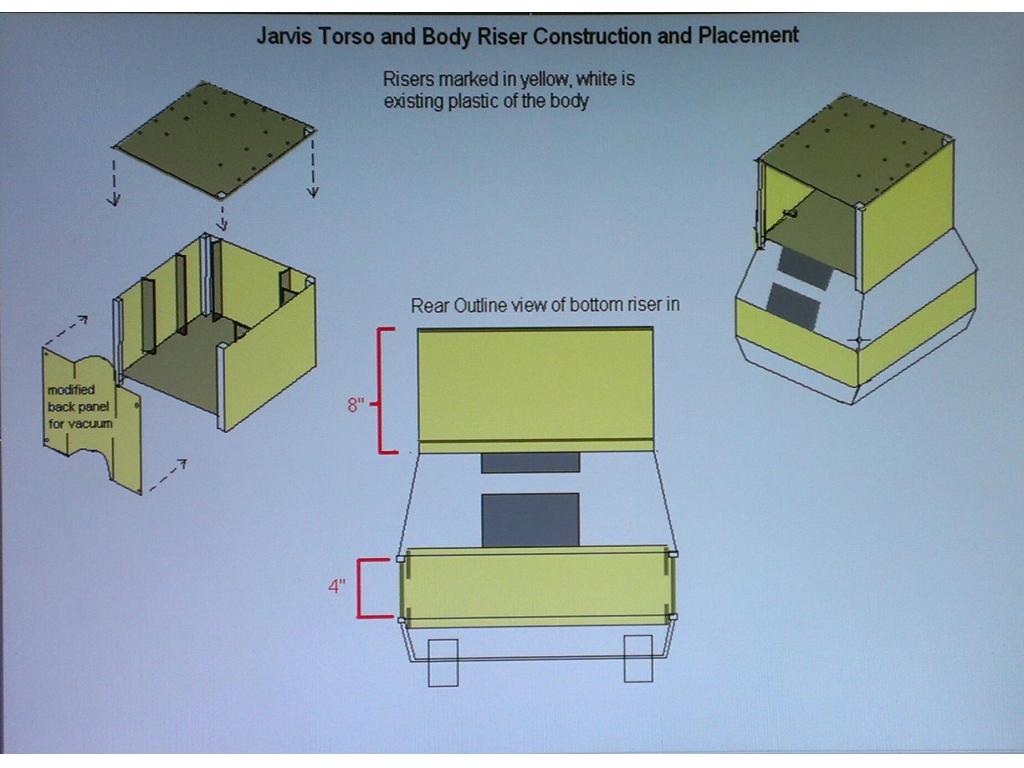
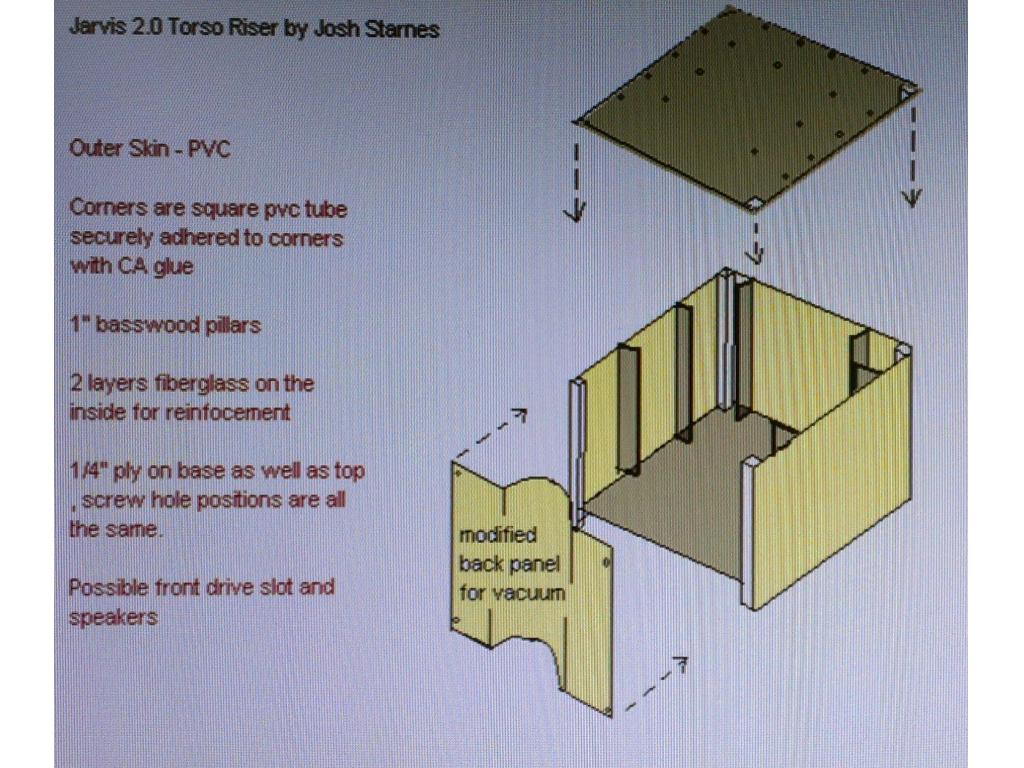
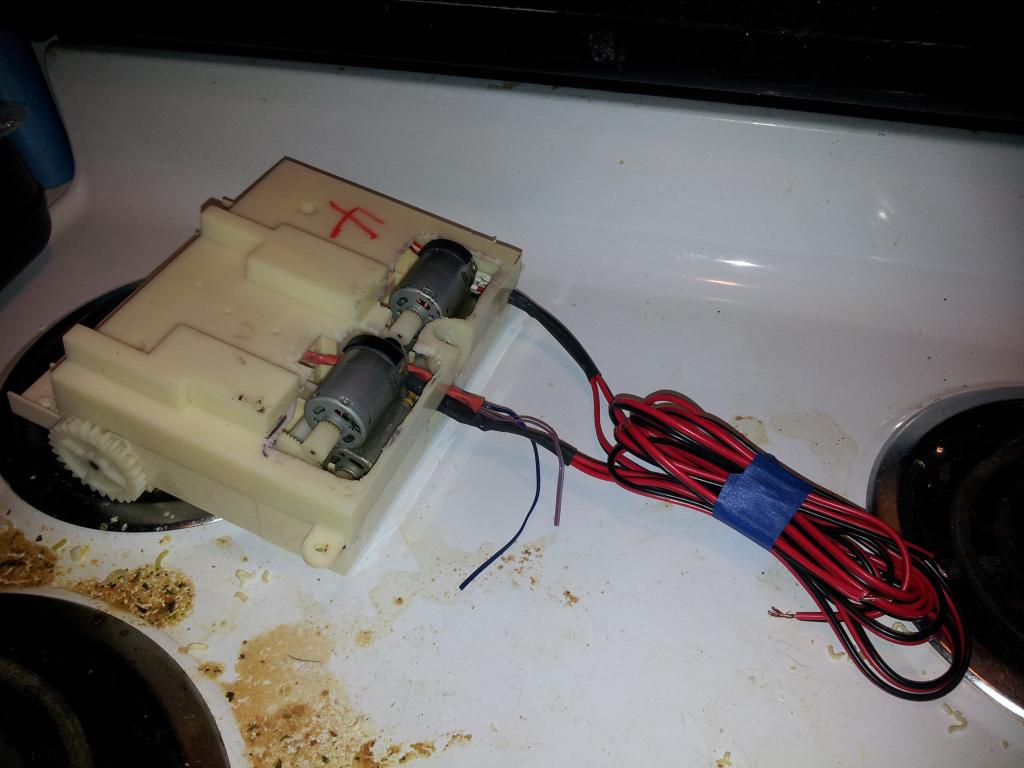
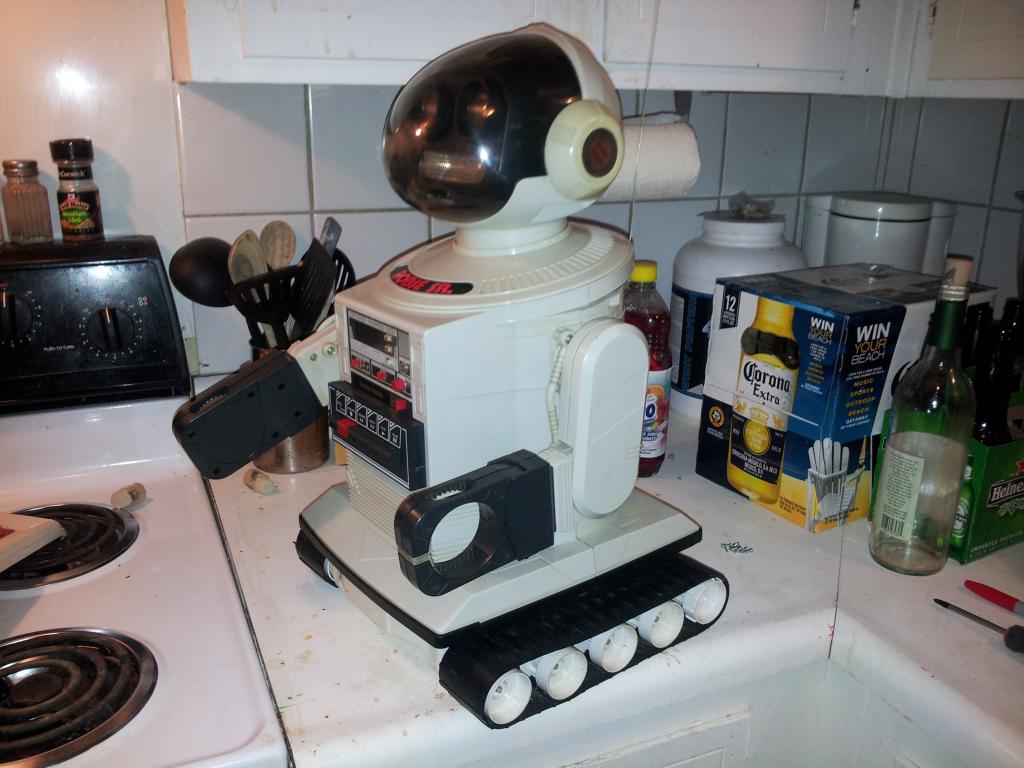
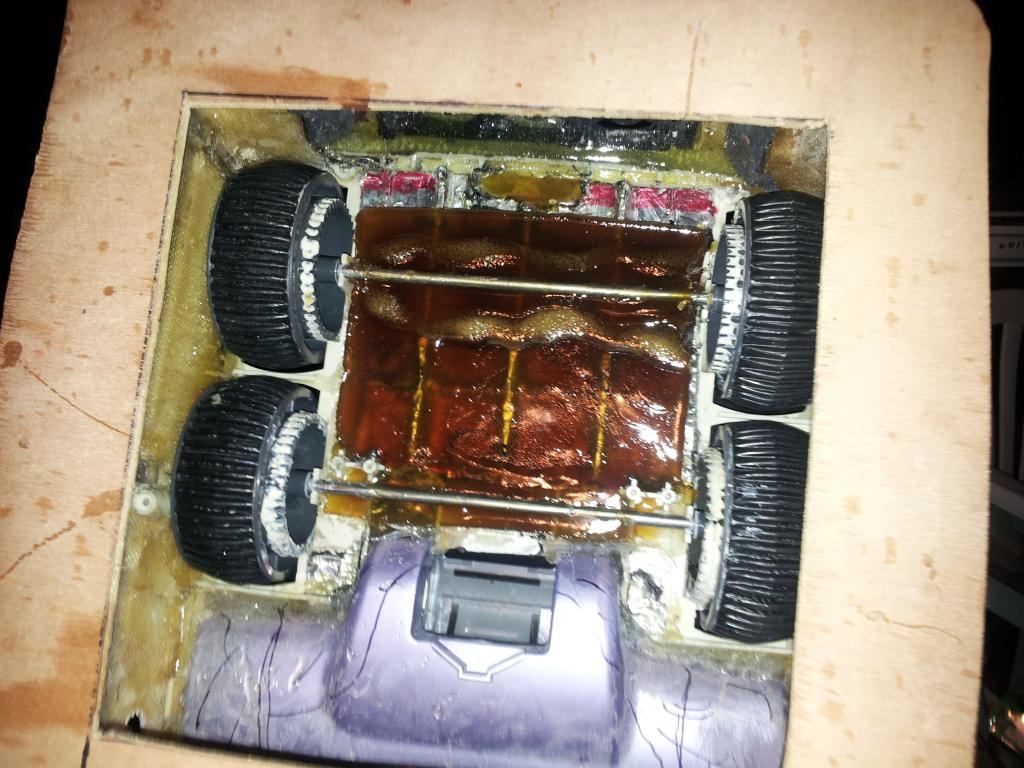
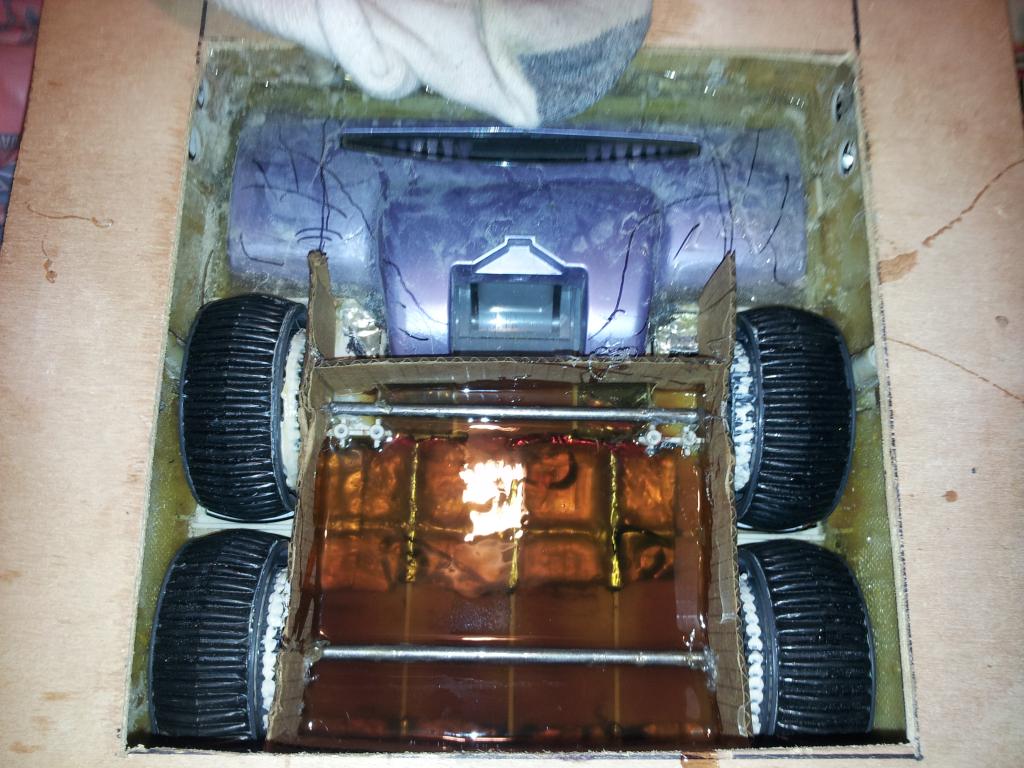
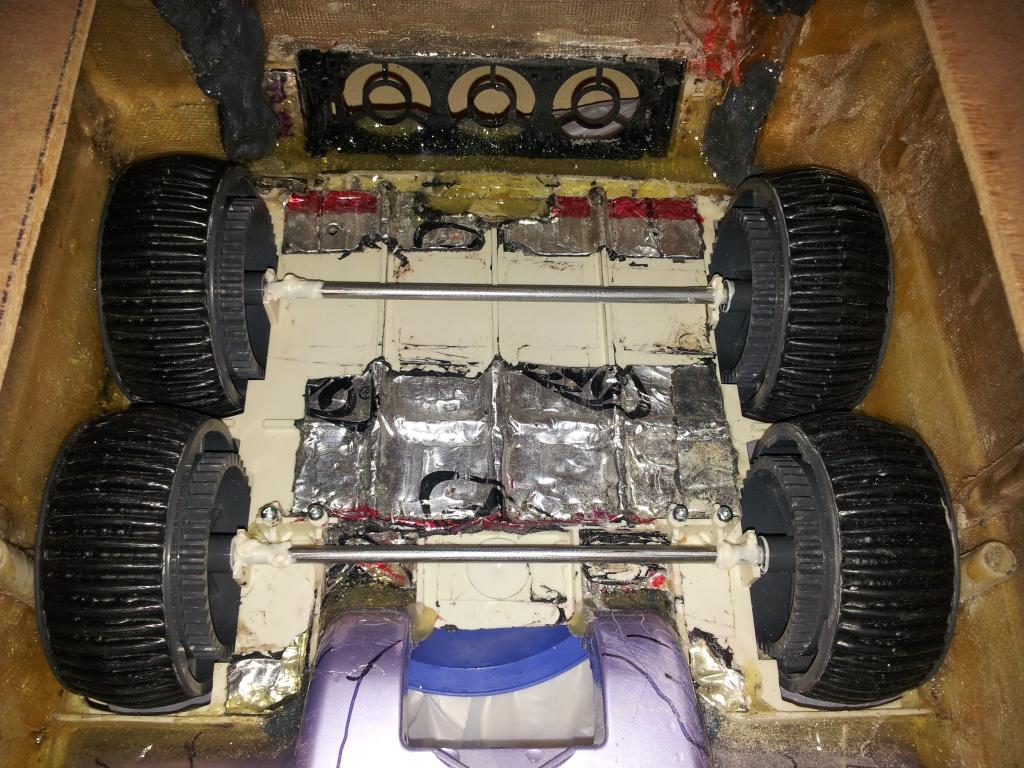
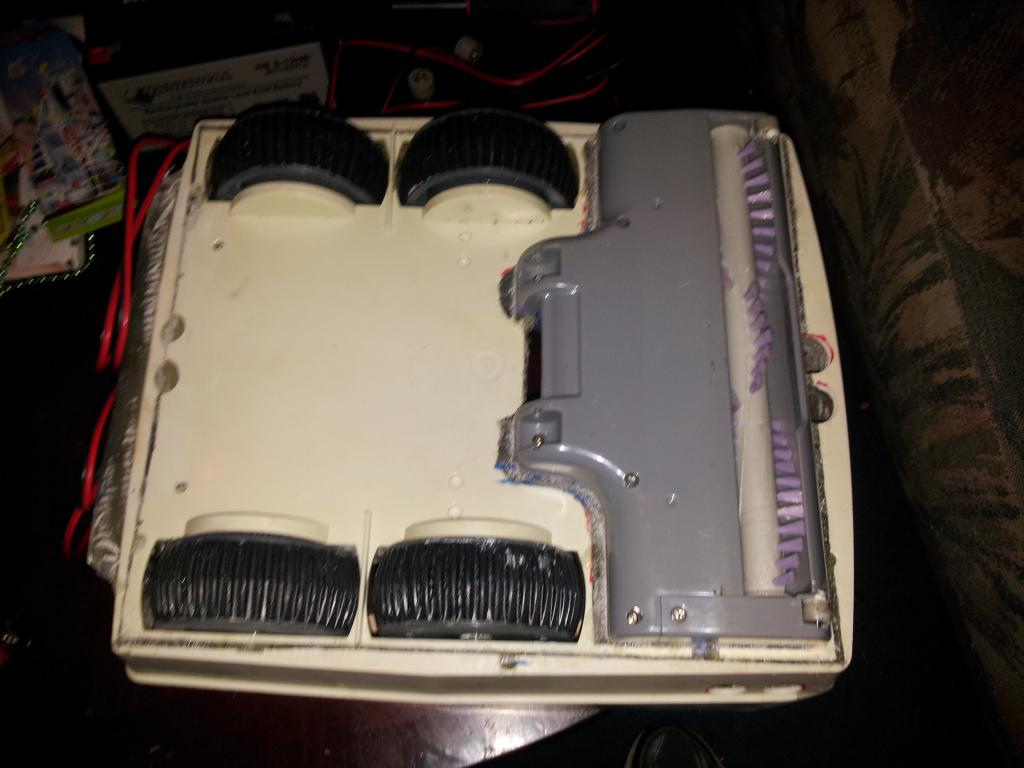
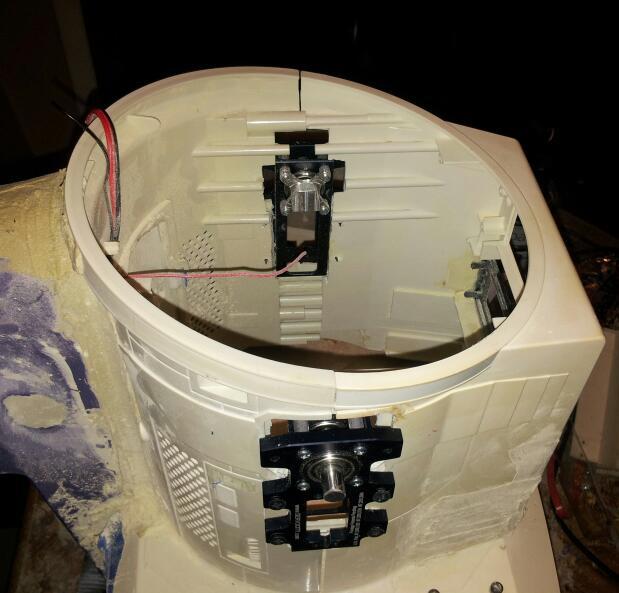
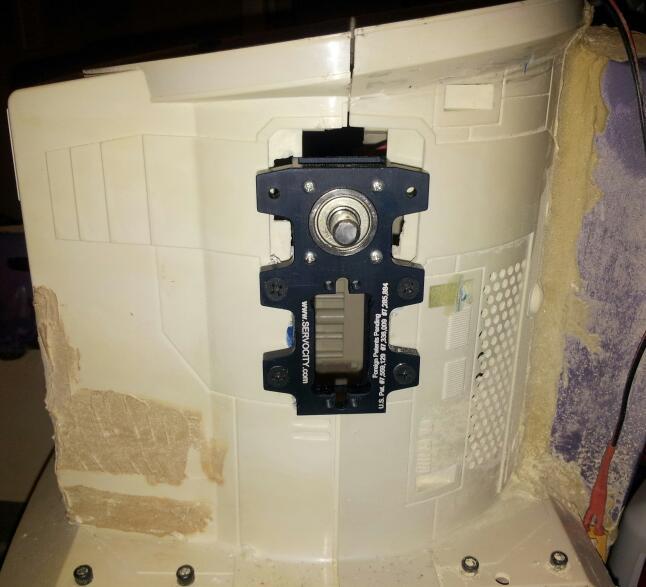
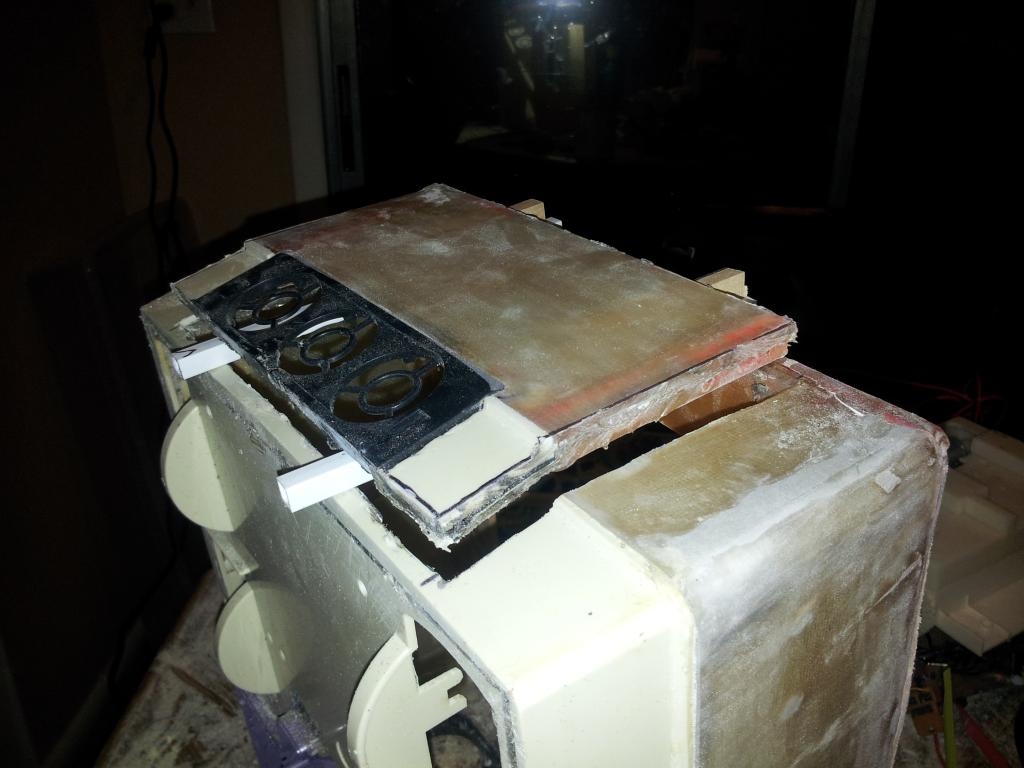
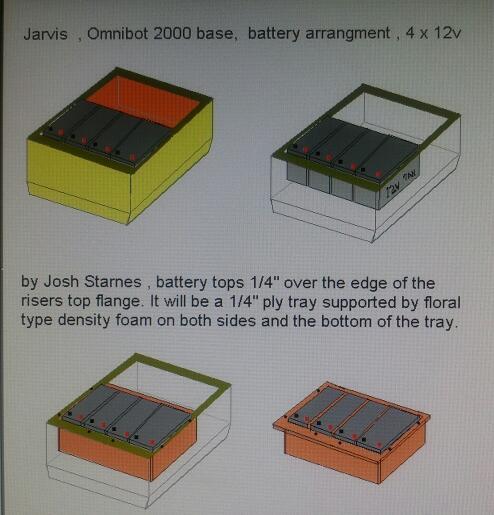
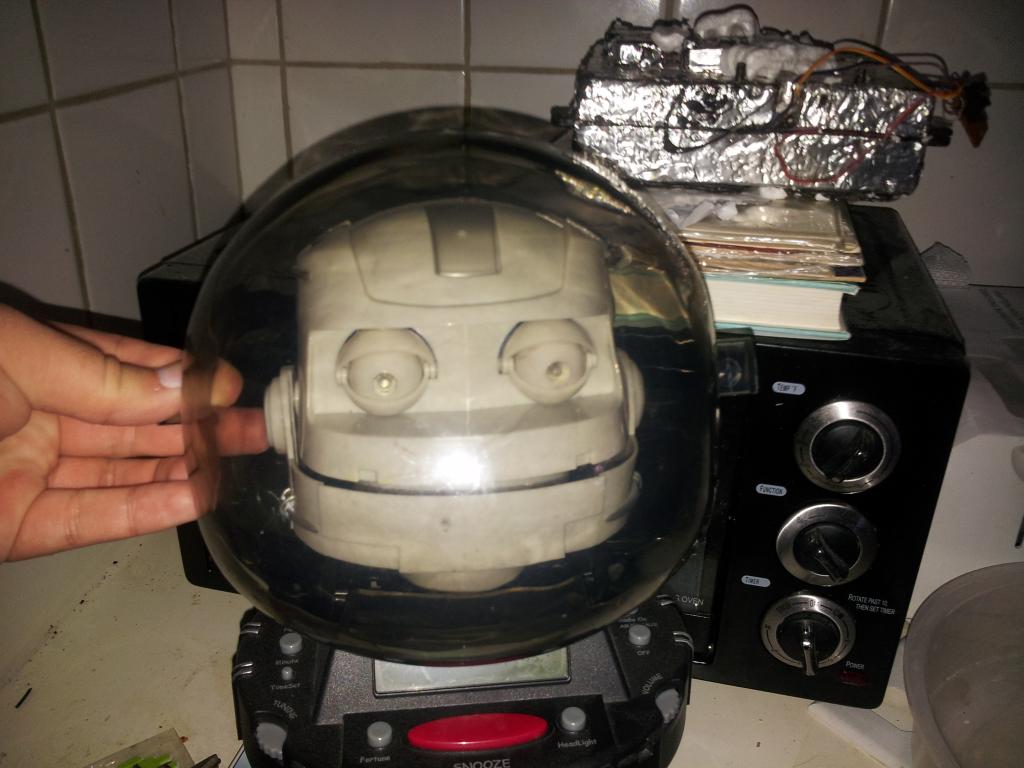
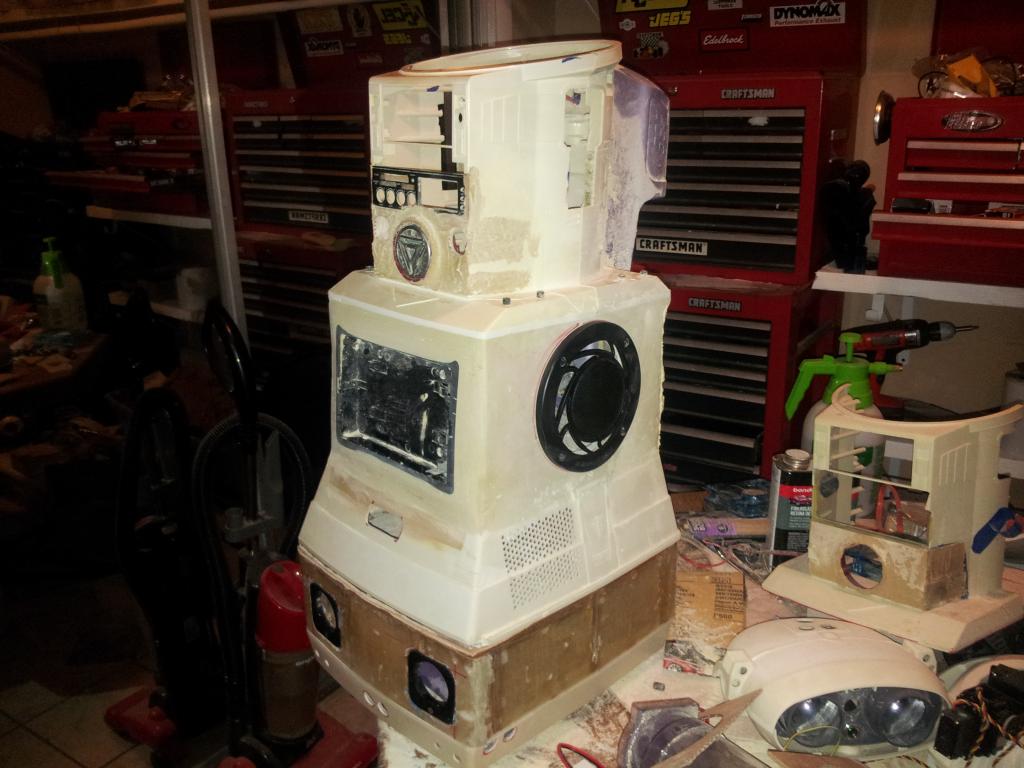
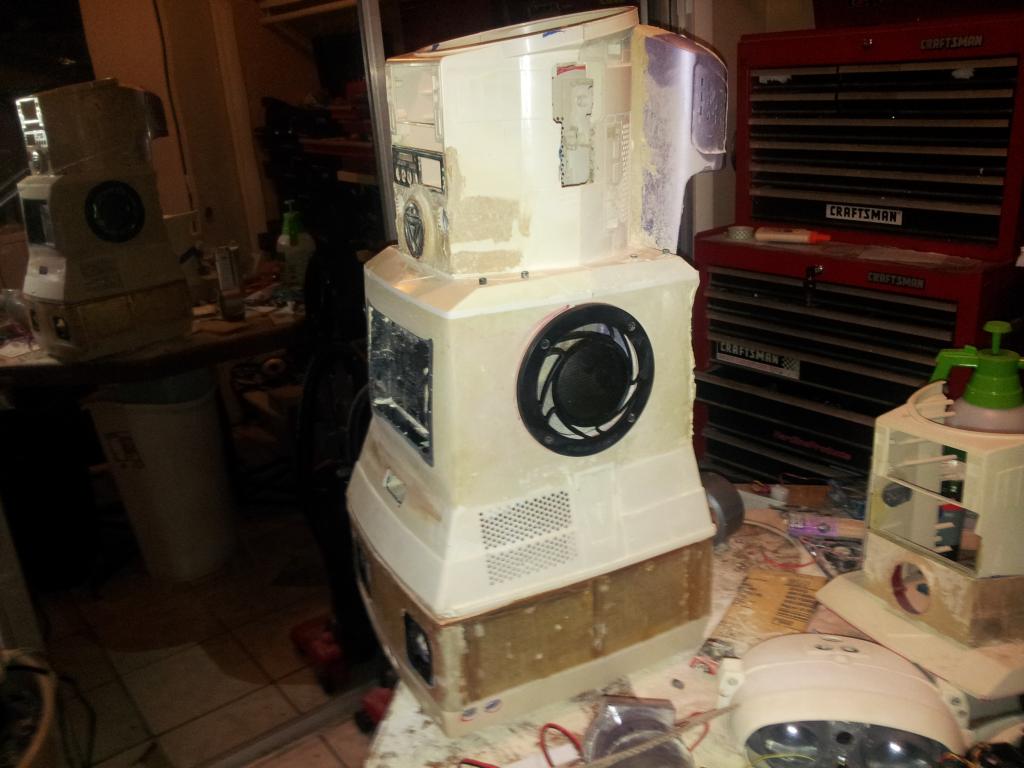
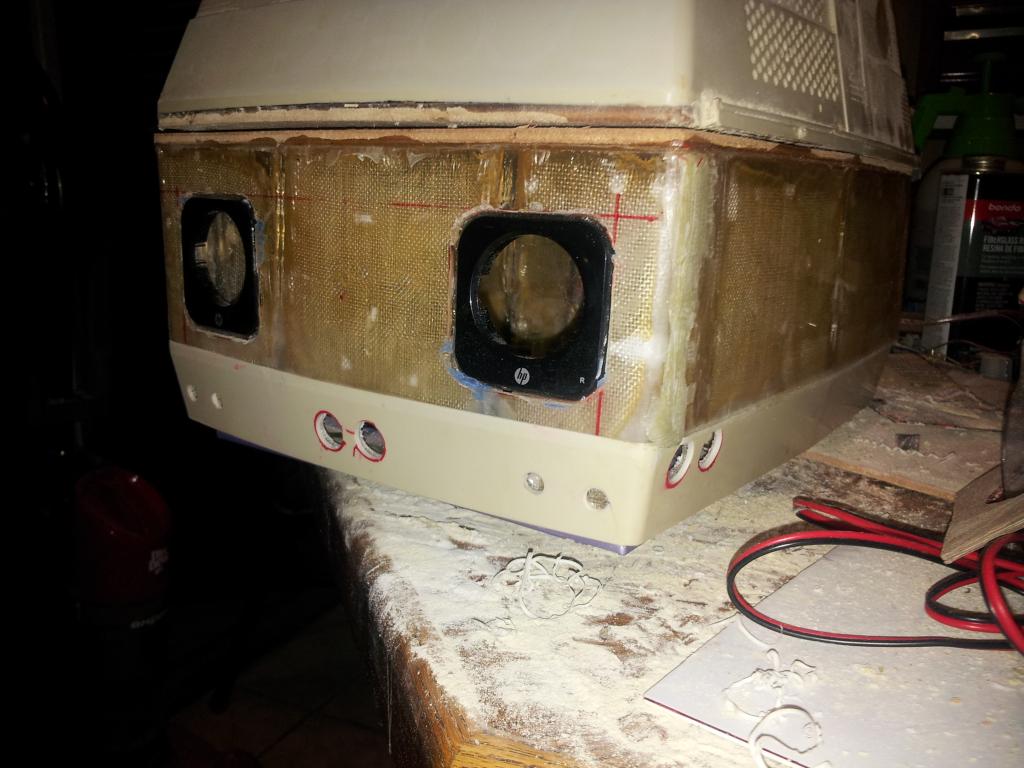
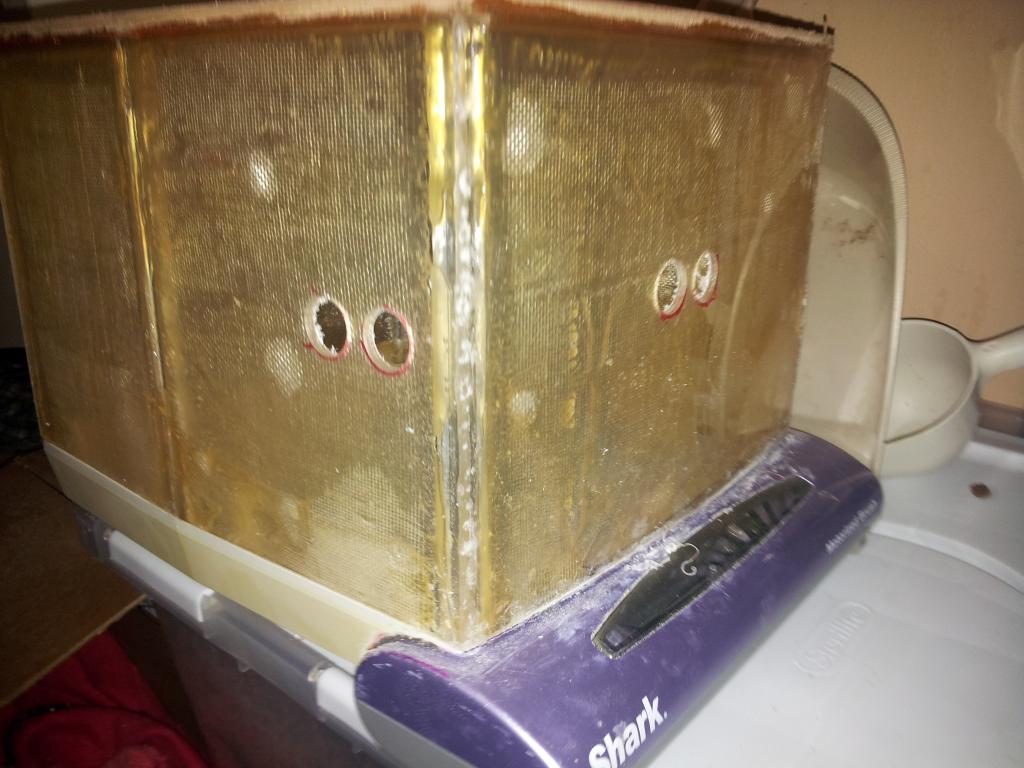
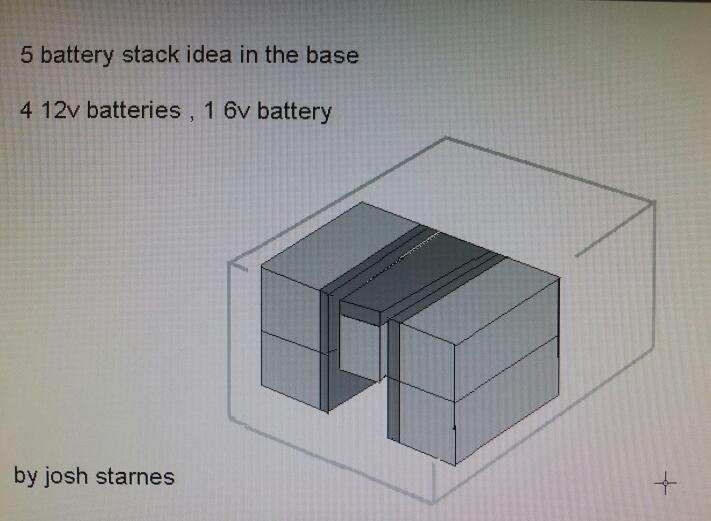
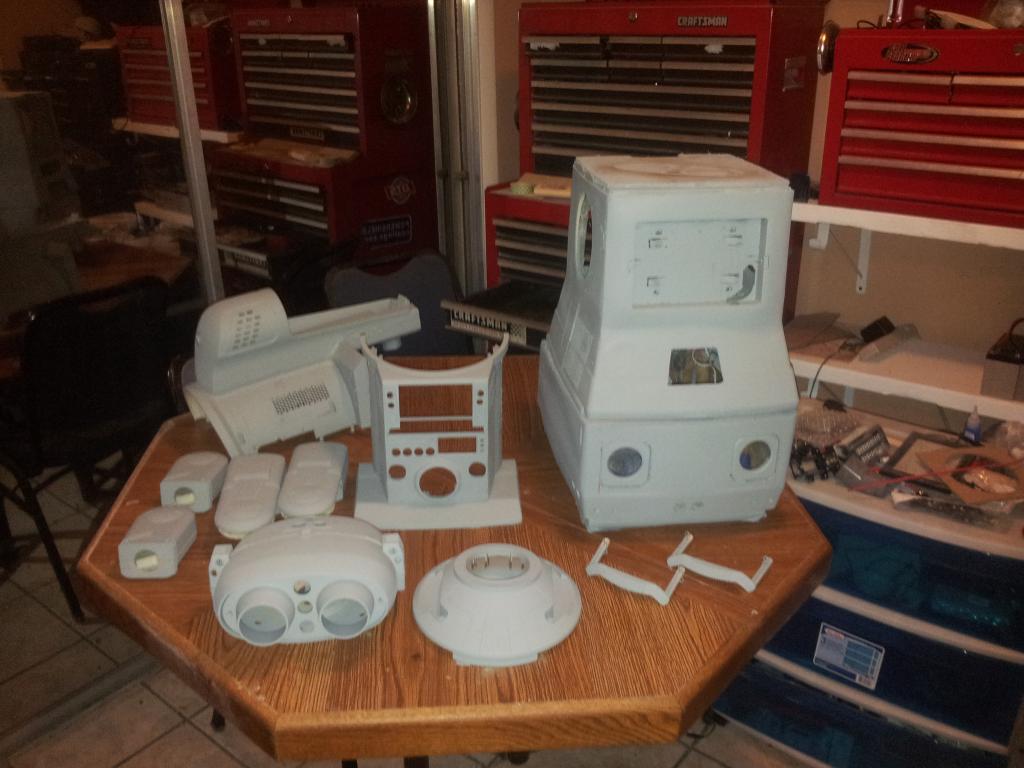
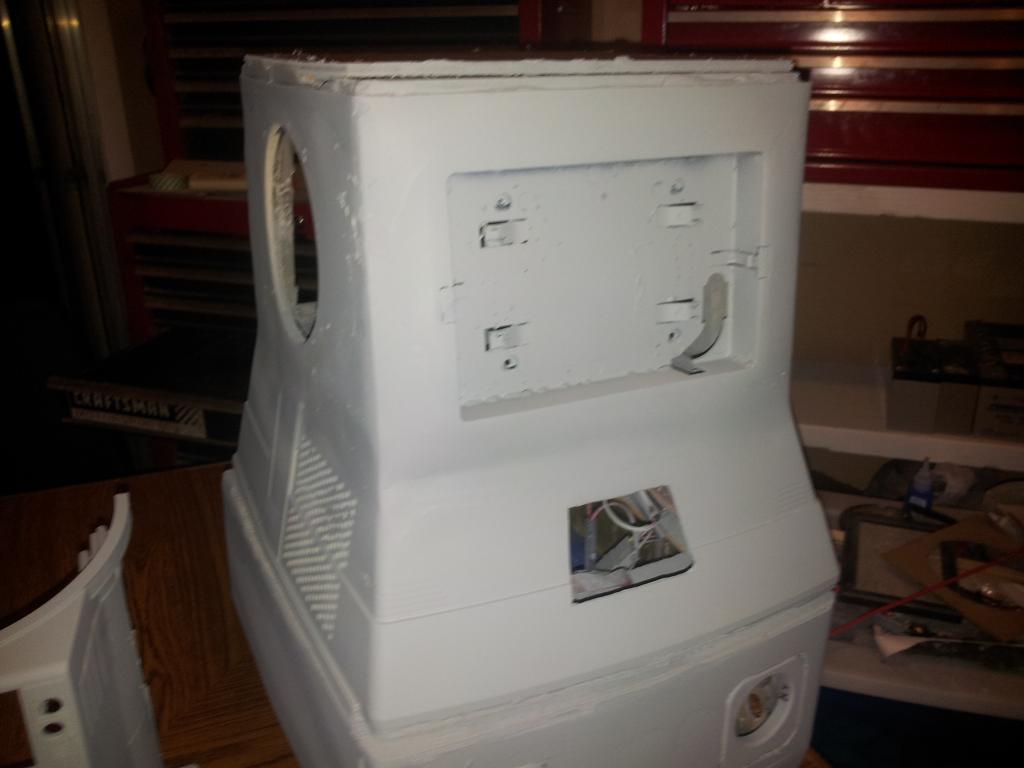
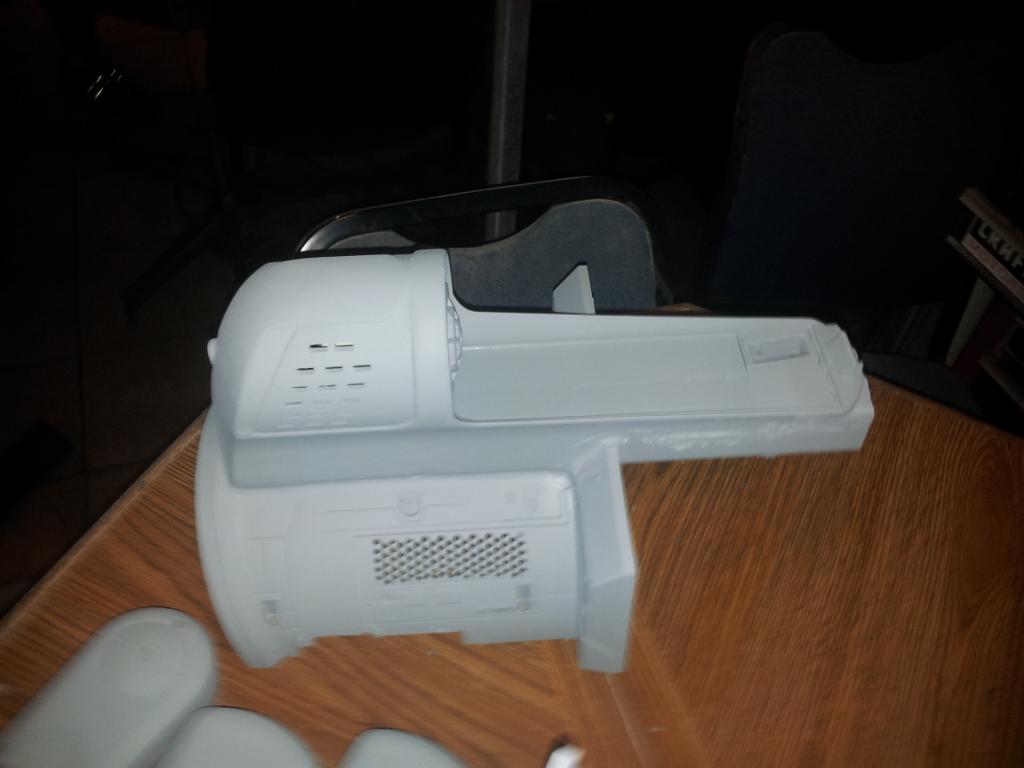
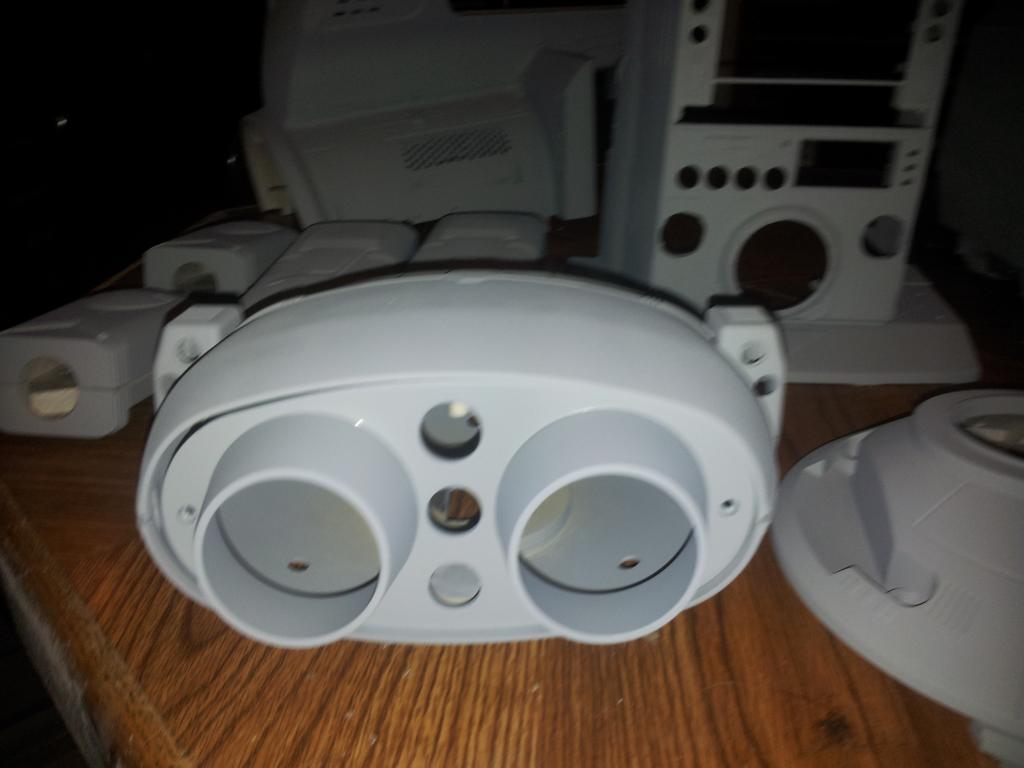
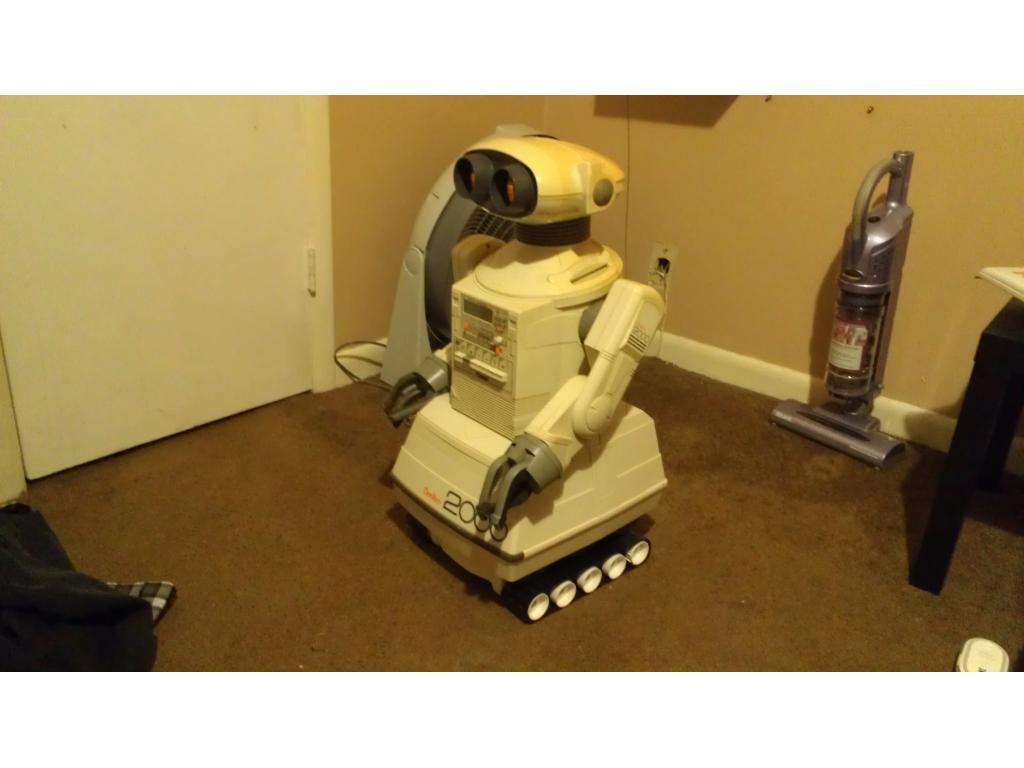
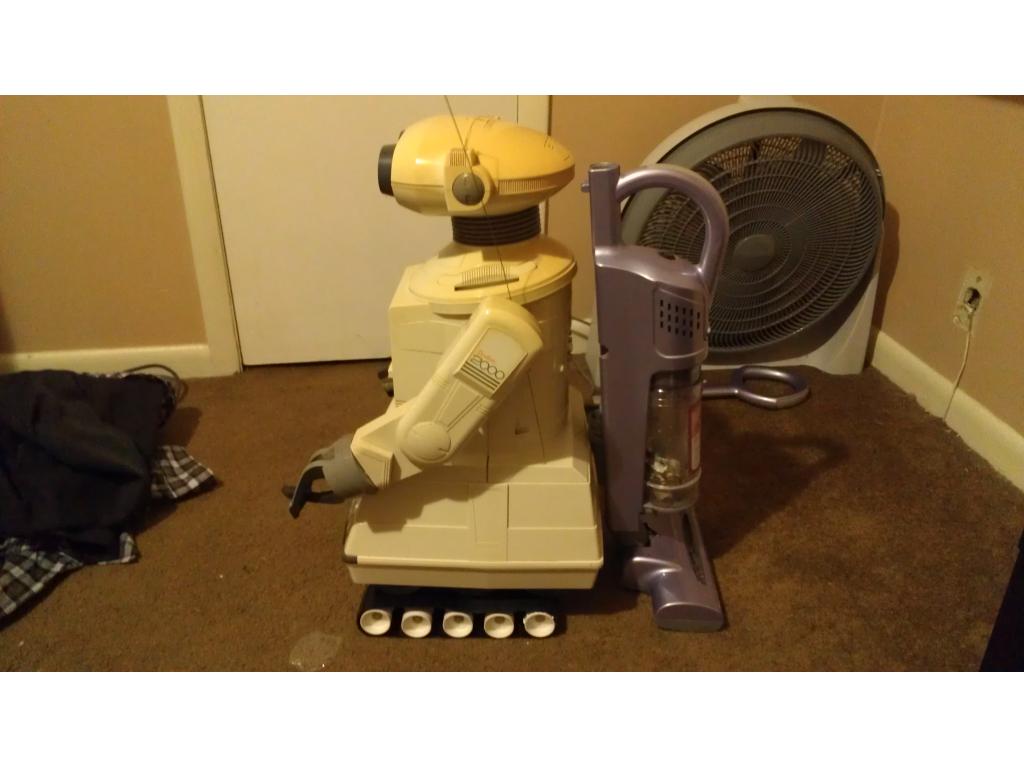
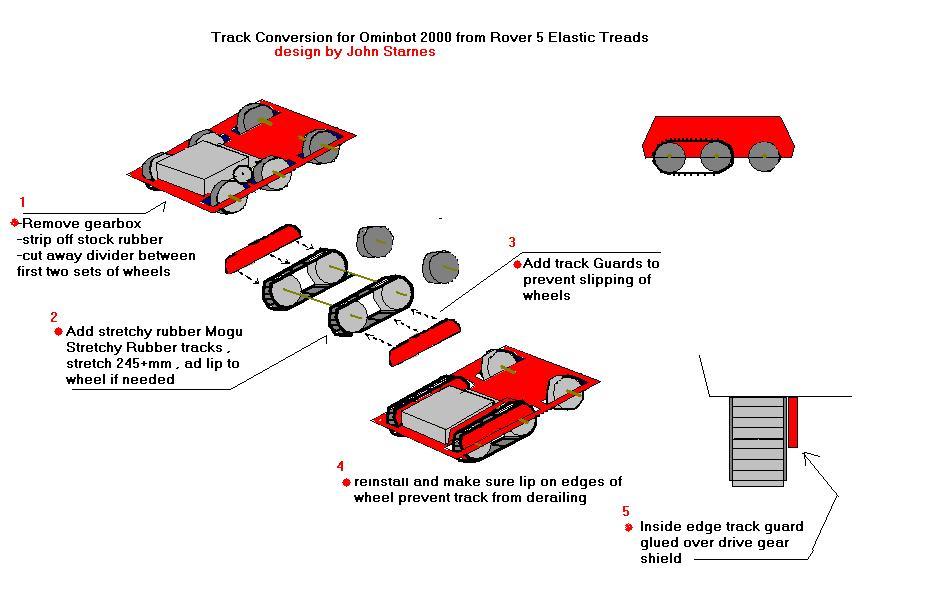
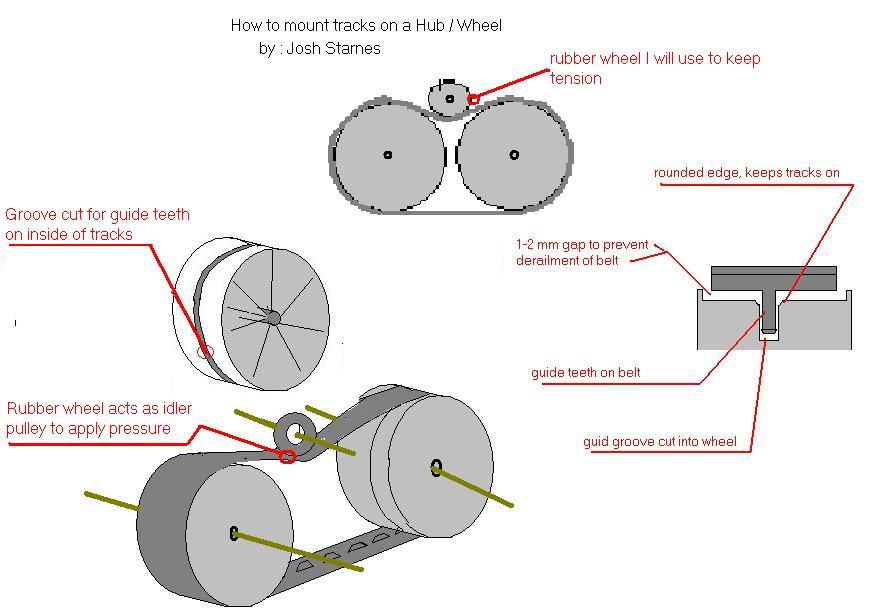
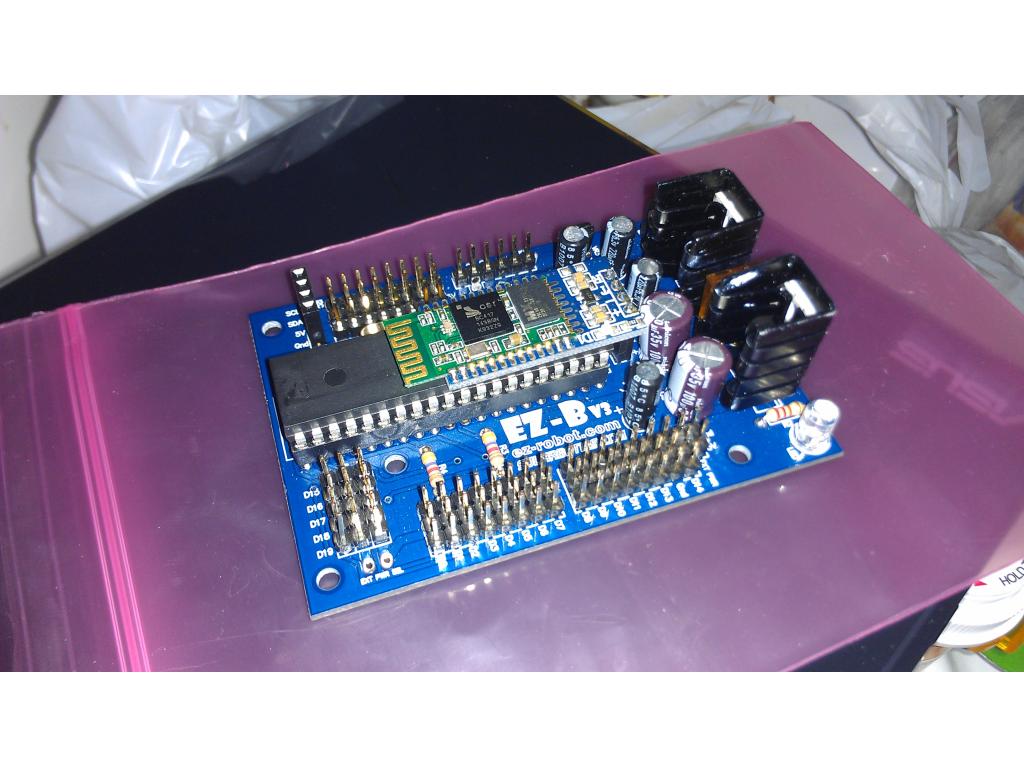
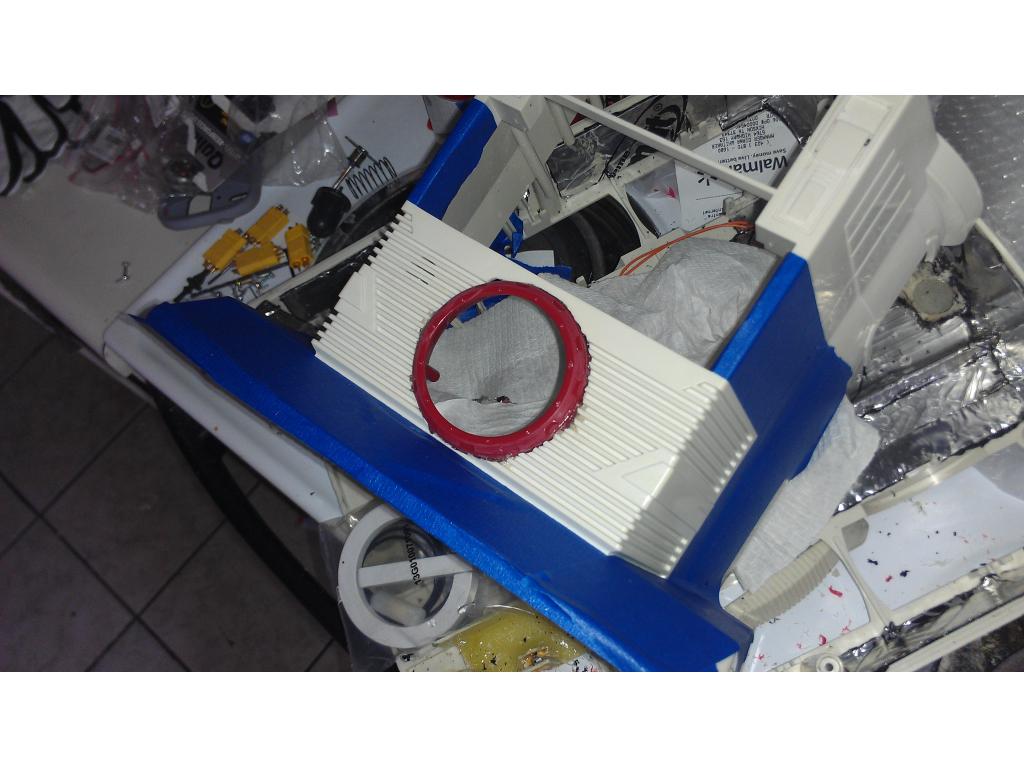
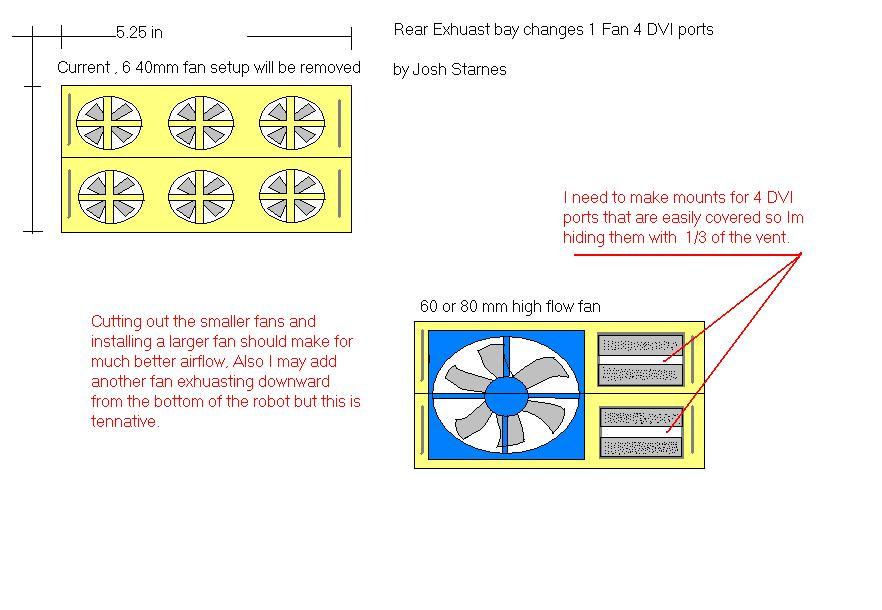
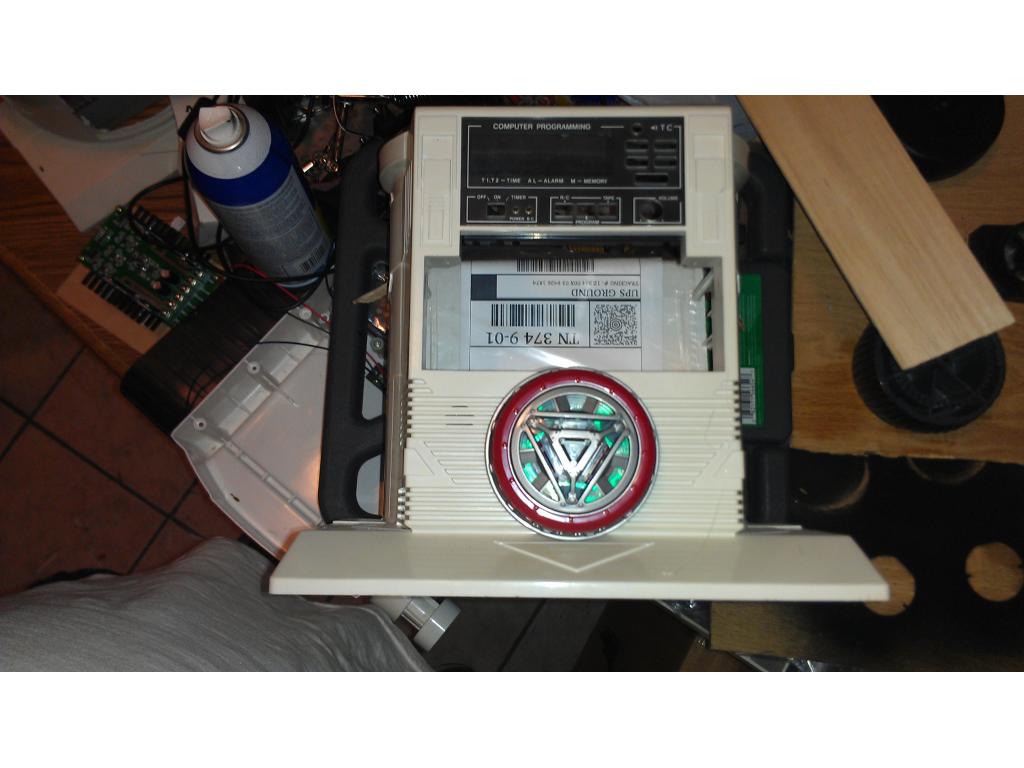
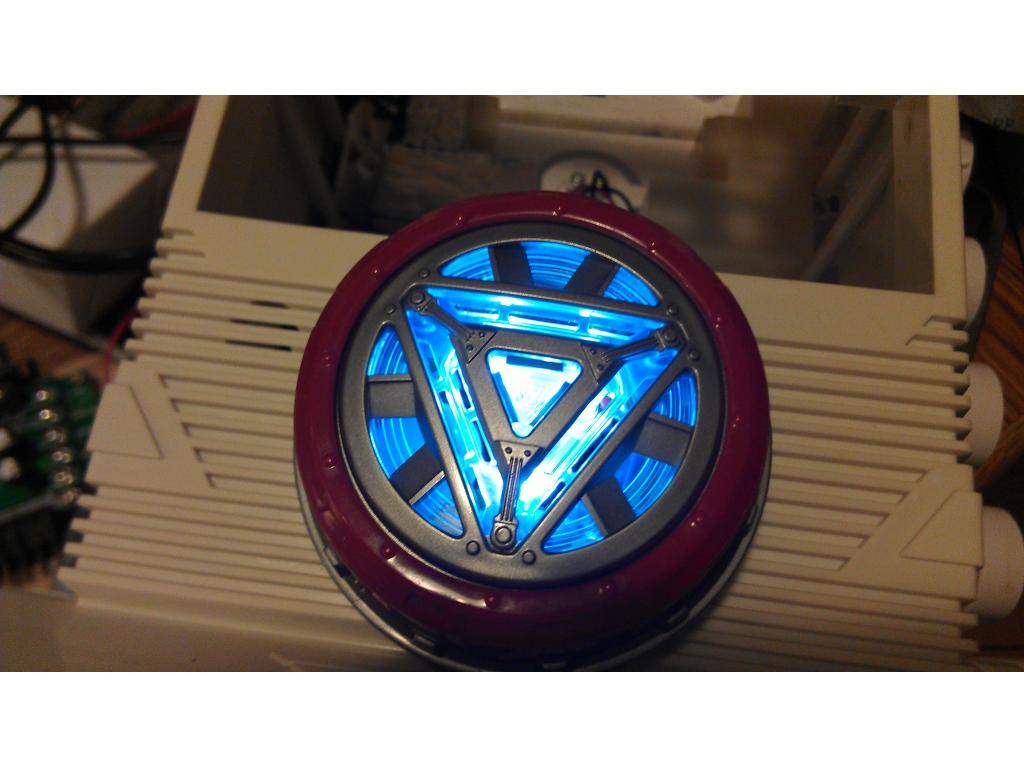
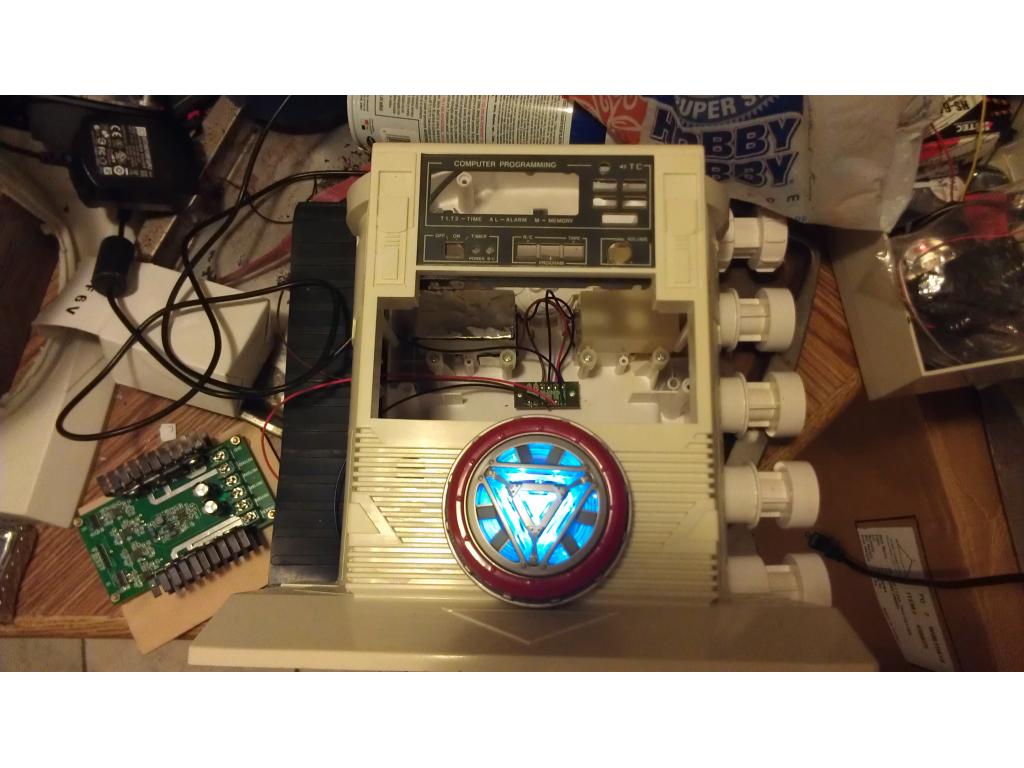
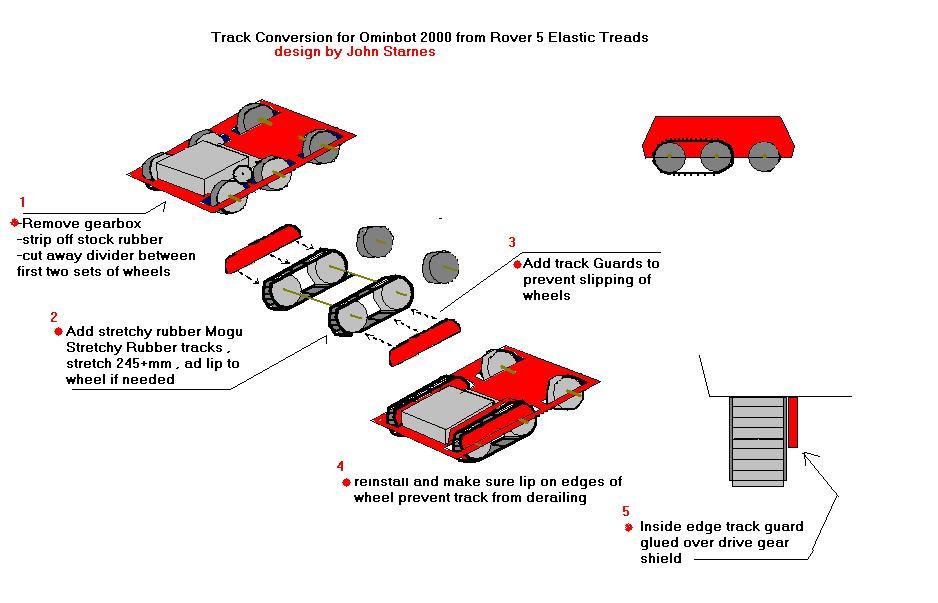
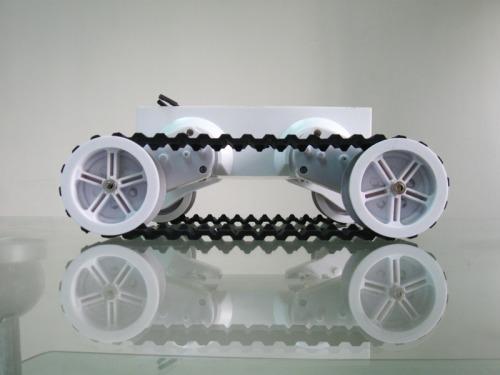
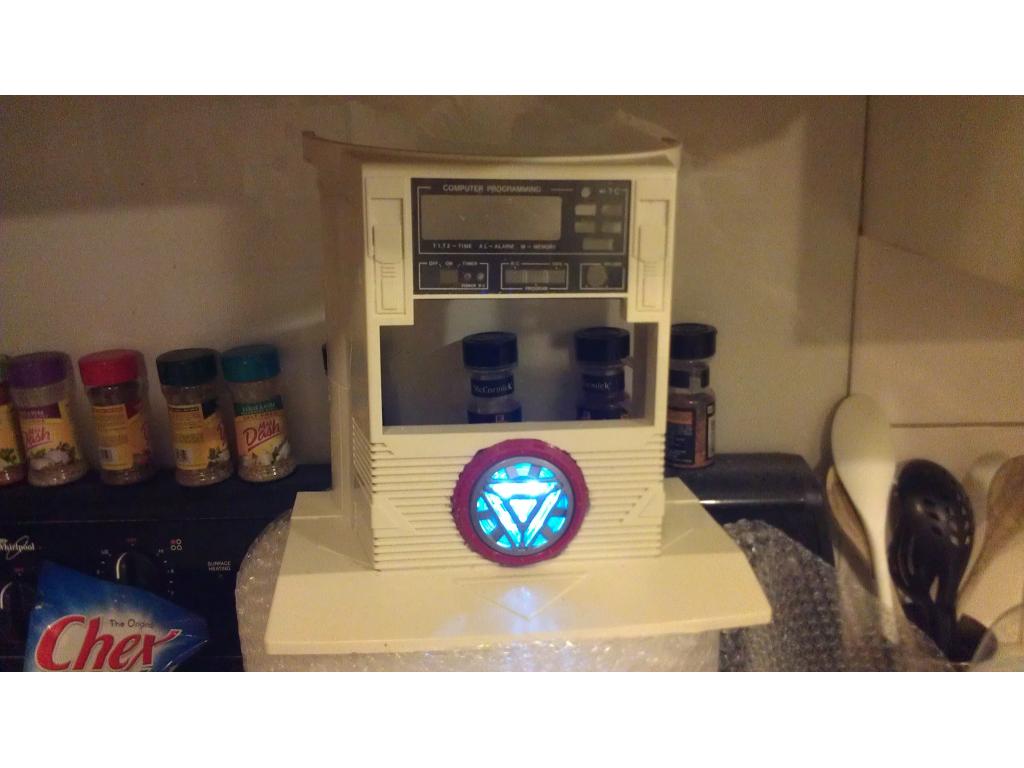
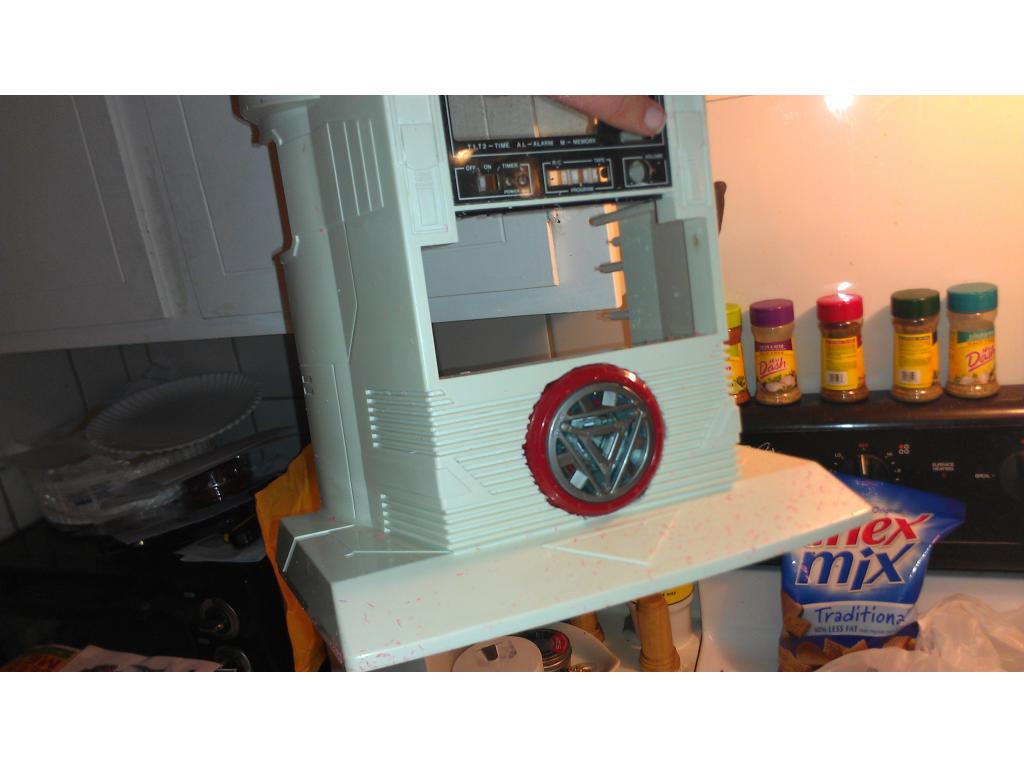
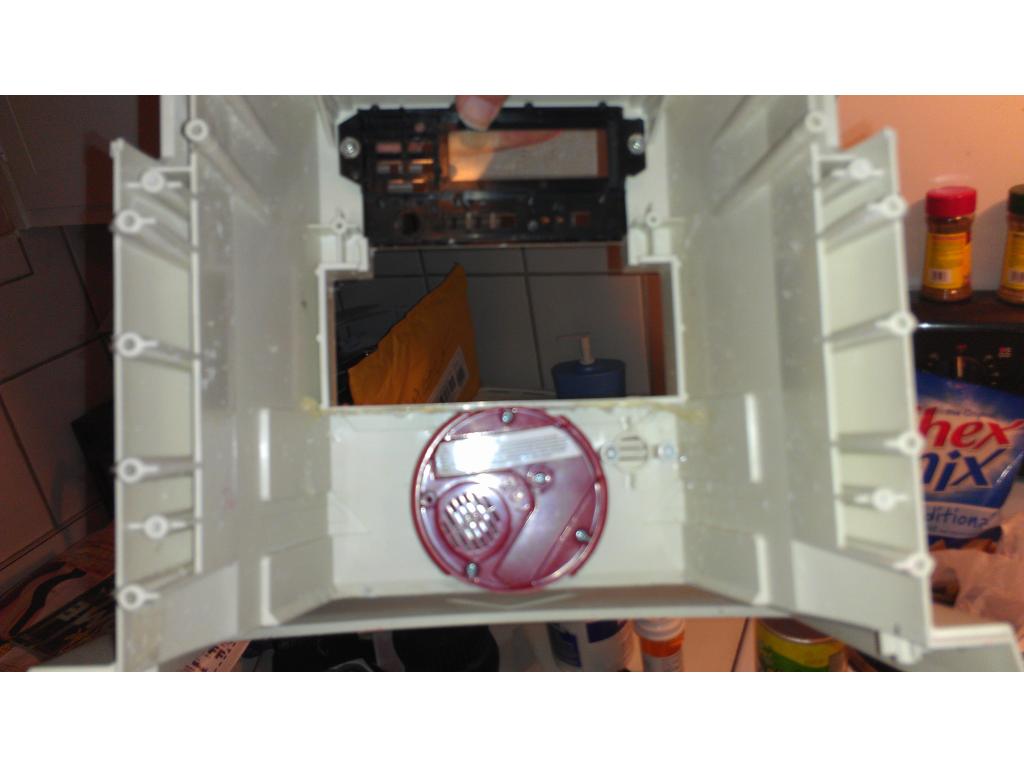
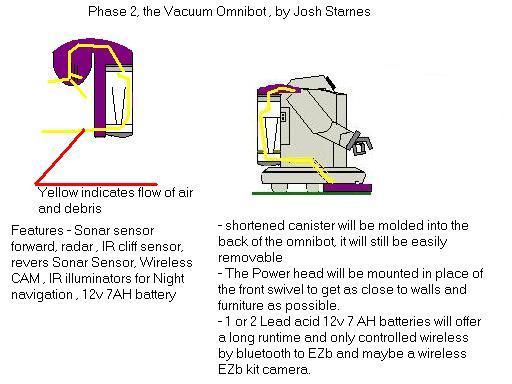
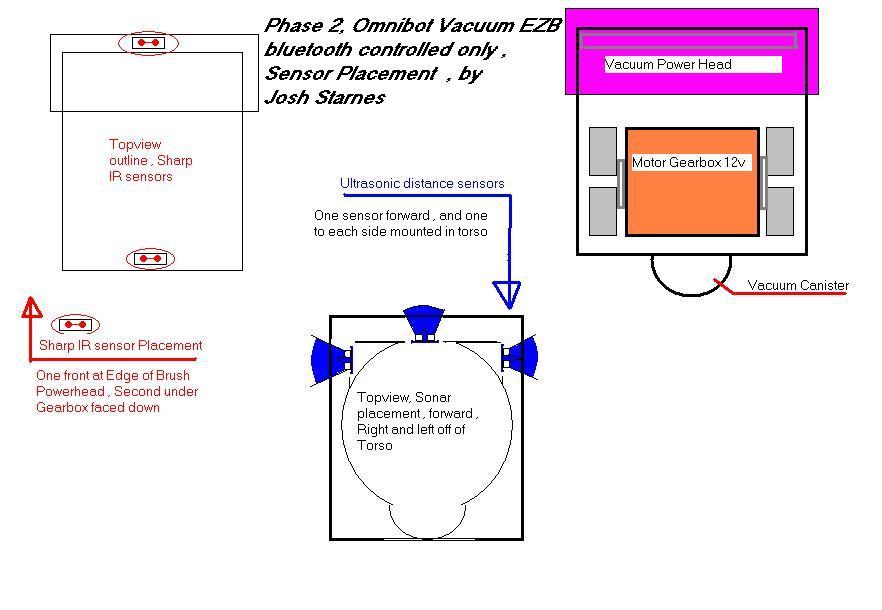
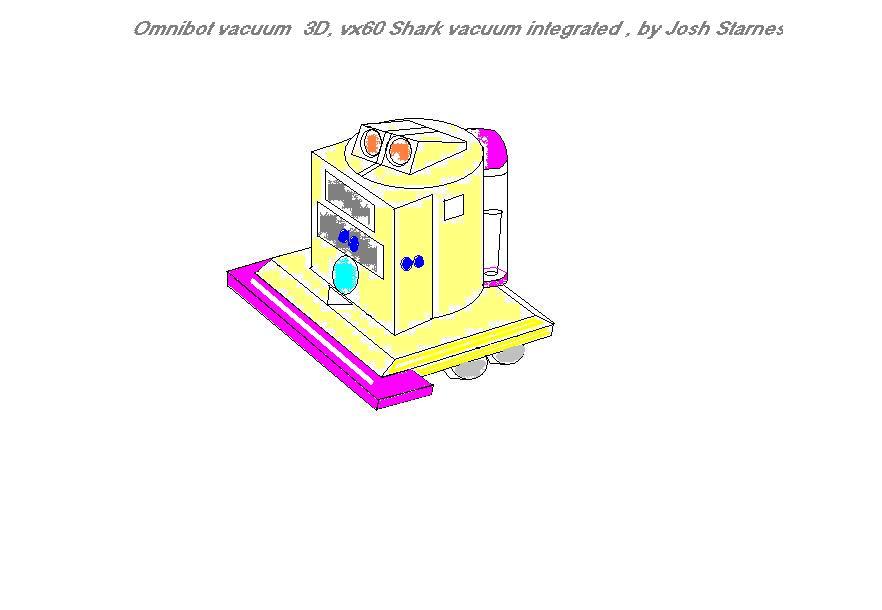
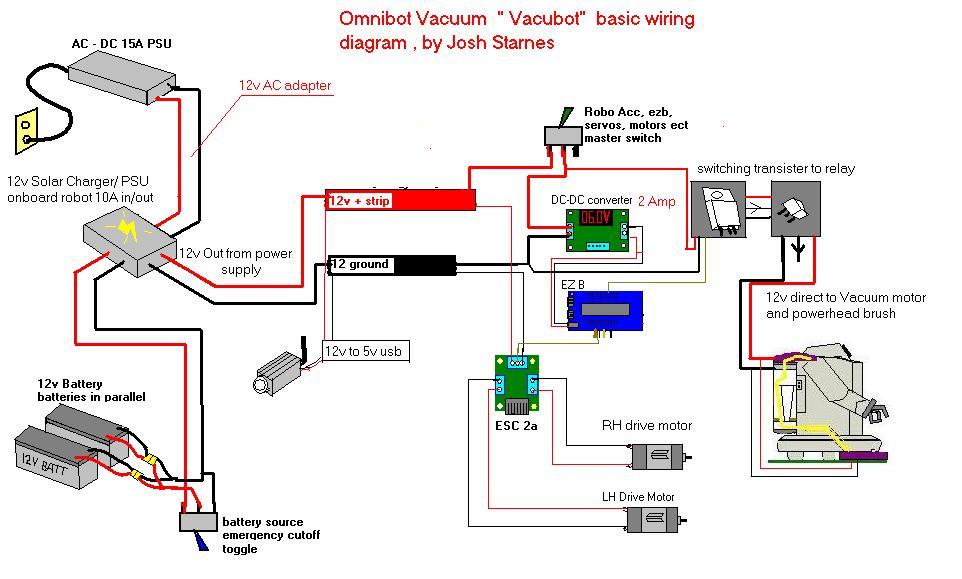
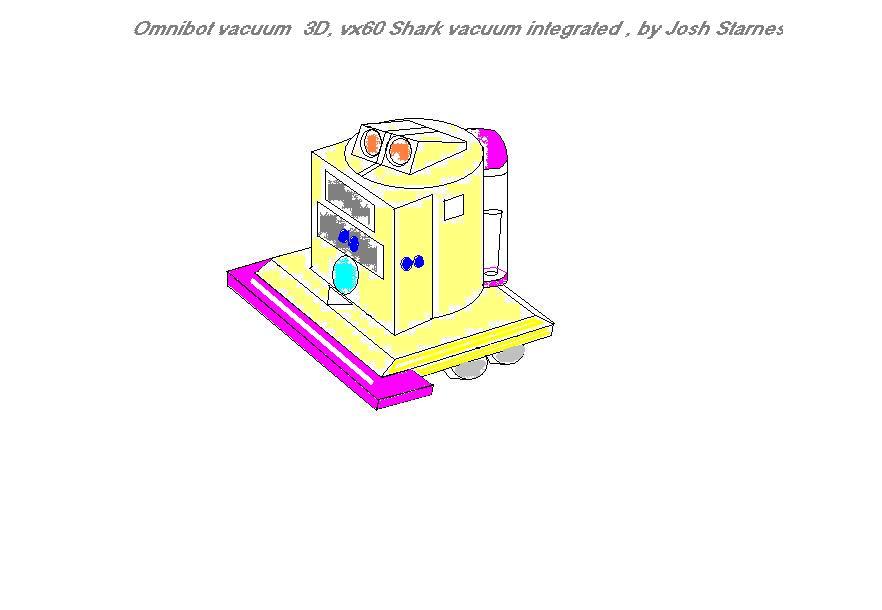
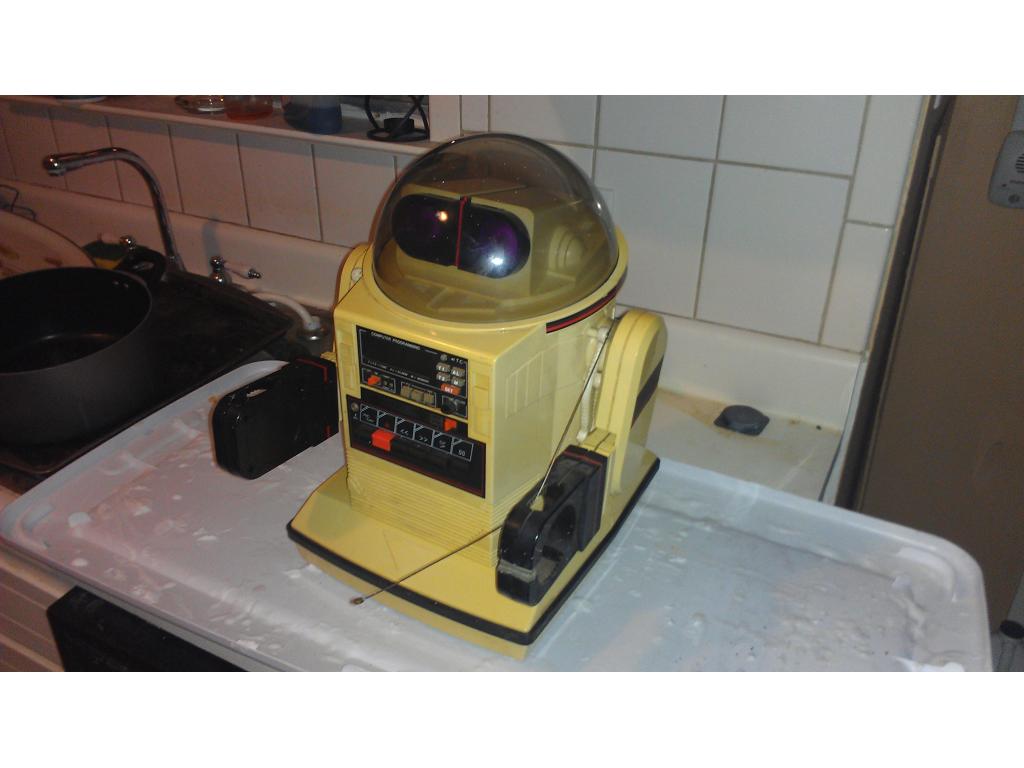
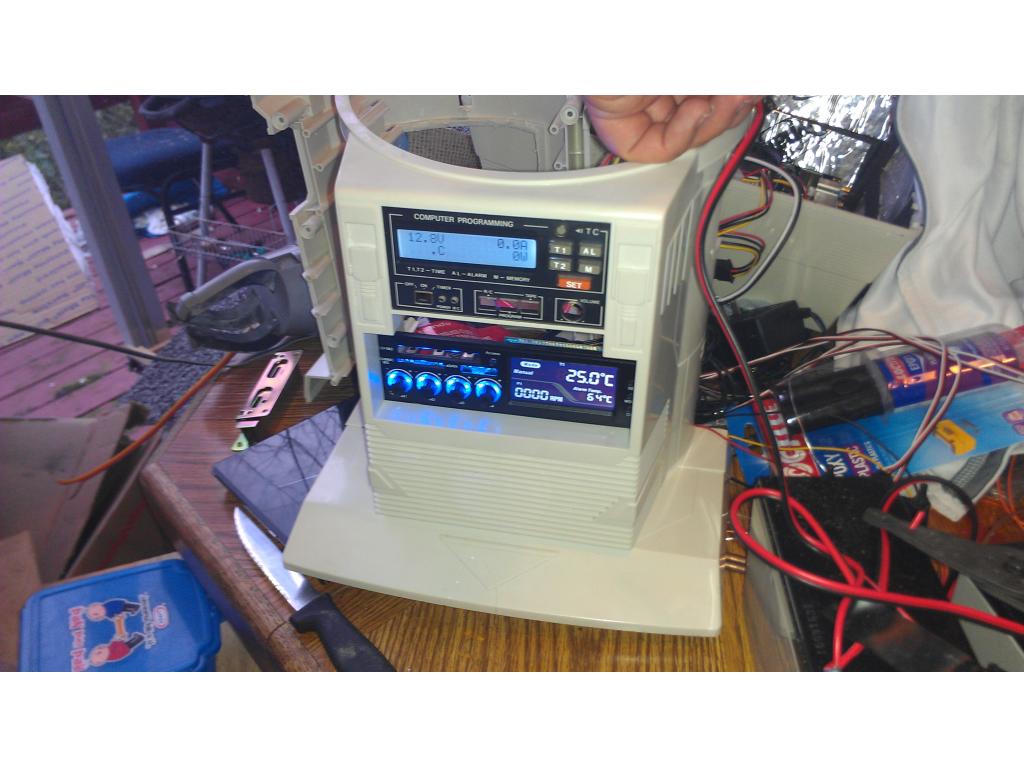
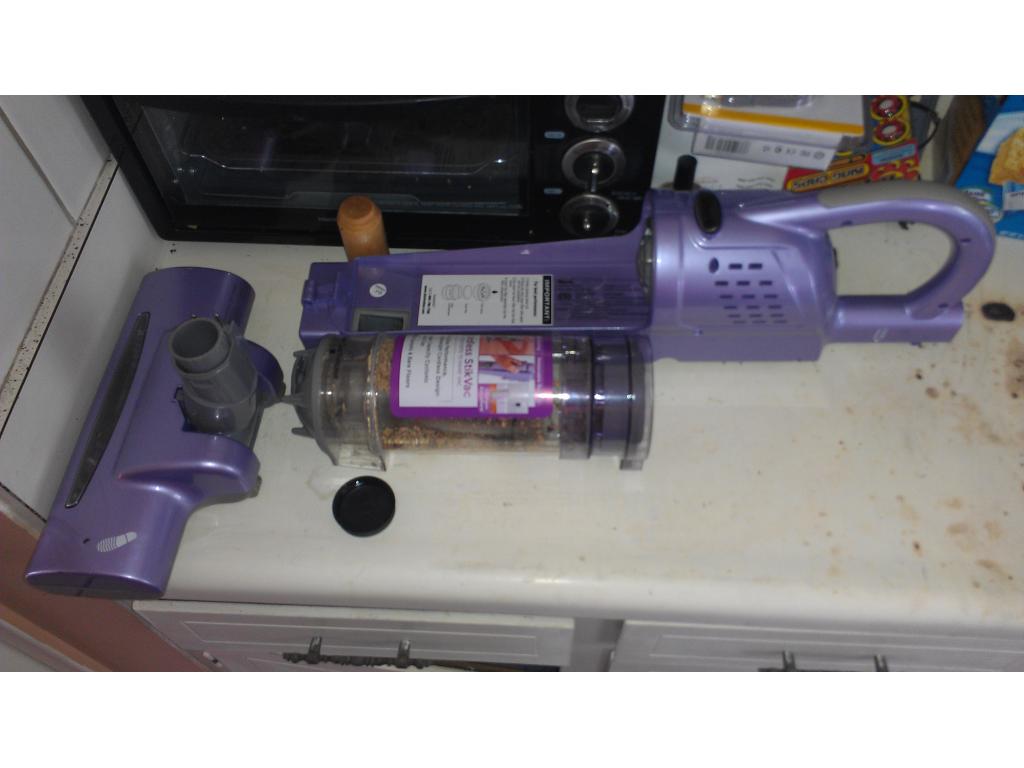
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.

By jstarne1
— Last update

Discover more robots
Rgordon's Magnus The 6 Ft Robot
Magnus: a 6 ft, 300 lb humanoid using wheelchair motors to drive tank treads; builder exploring E Z Robot kit and...
Dunning-Kruger's My Inmoov Bartender
Autonomous inMoov bartender using Luis Vazquez TTS jaw movement, inspired by Bob Houston; showcases full autonomy and...
51M0n76's Meet Arnie
Homebuilt robot Arnie with pan/tilt head that looks around freely; awaiting H-bridge for mobility, plus paint and arms.

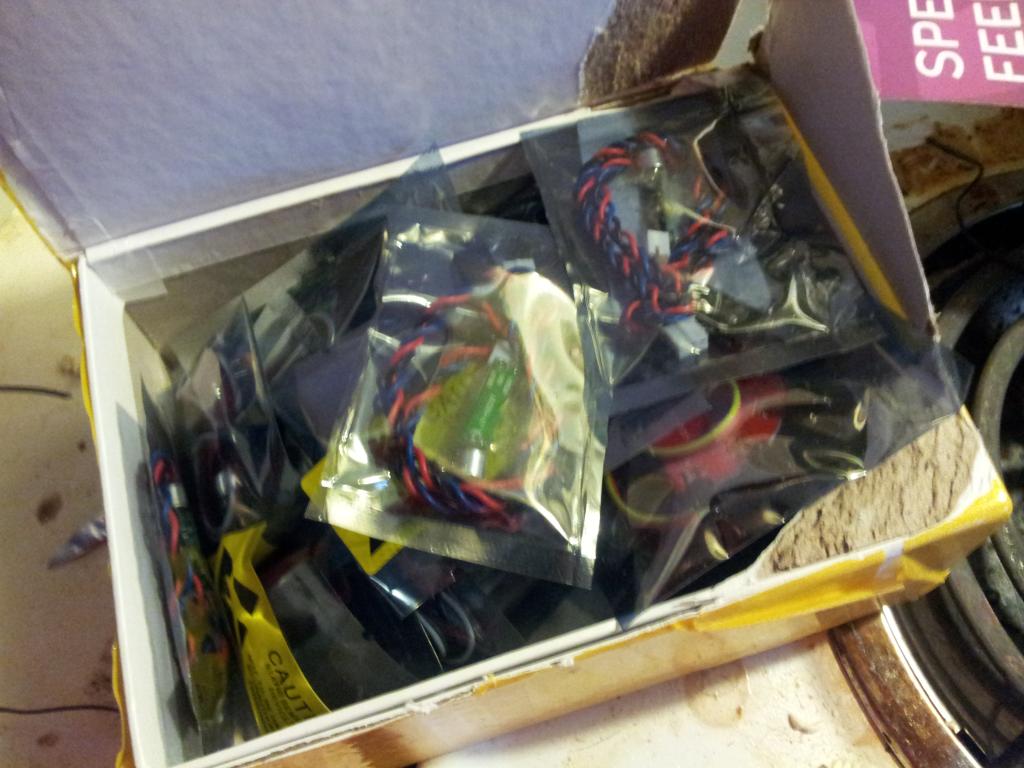
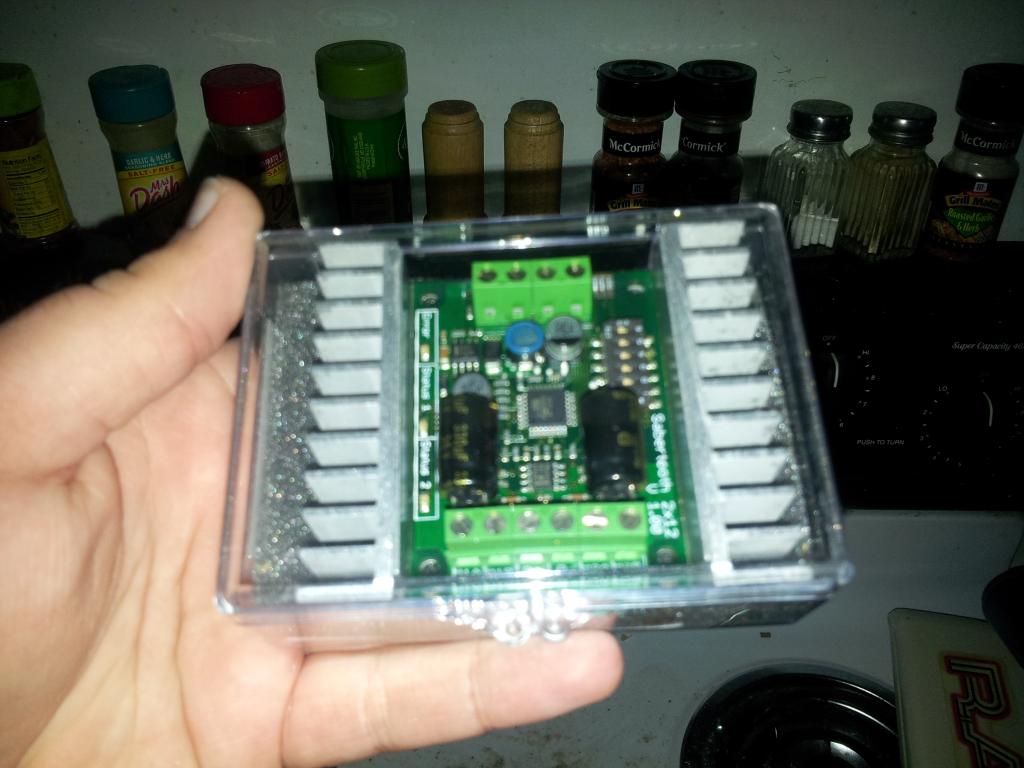
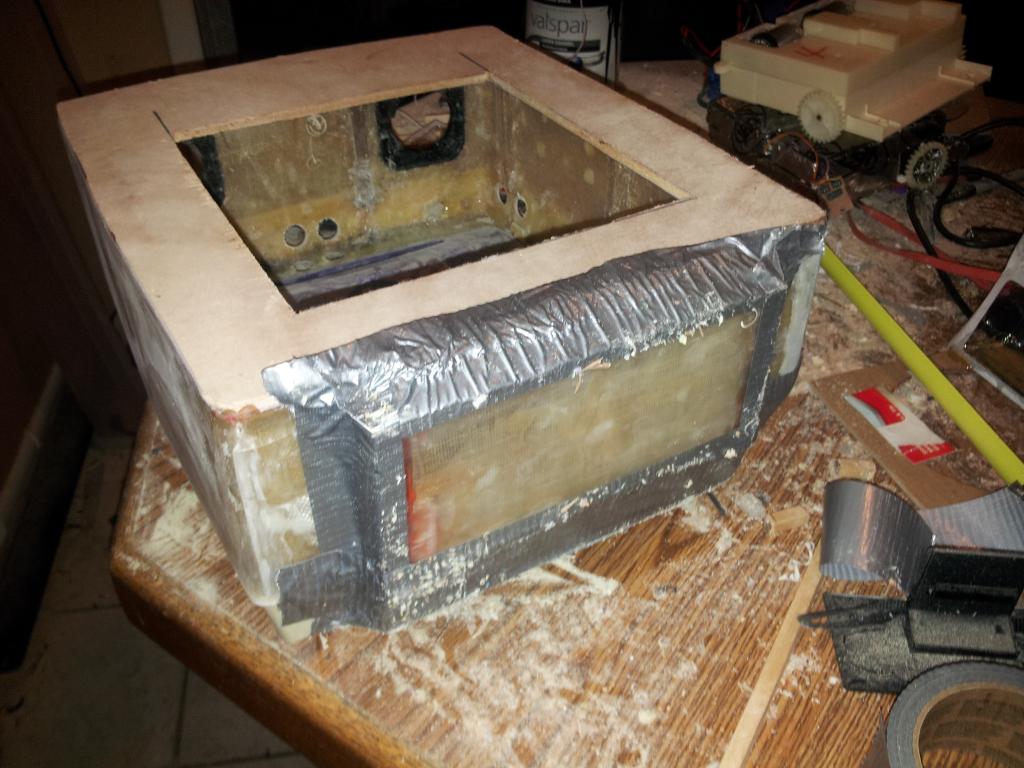
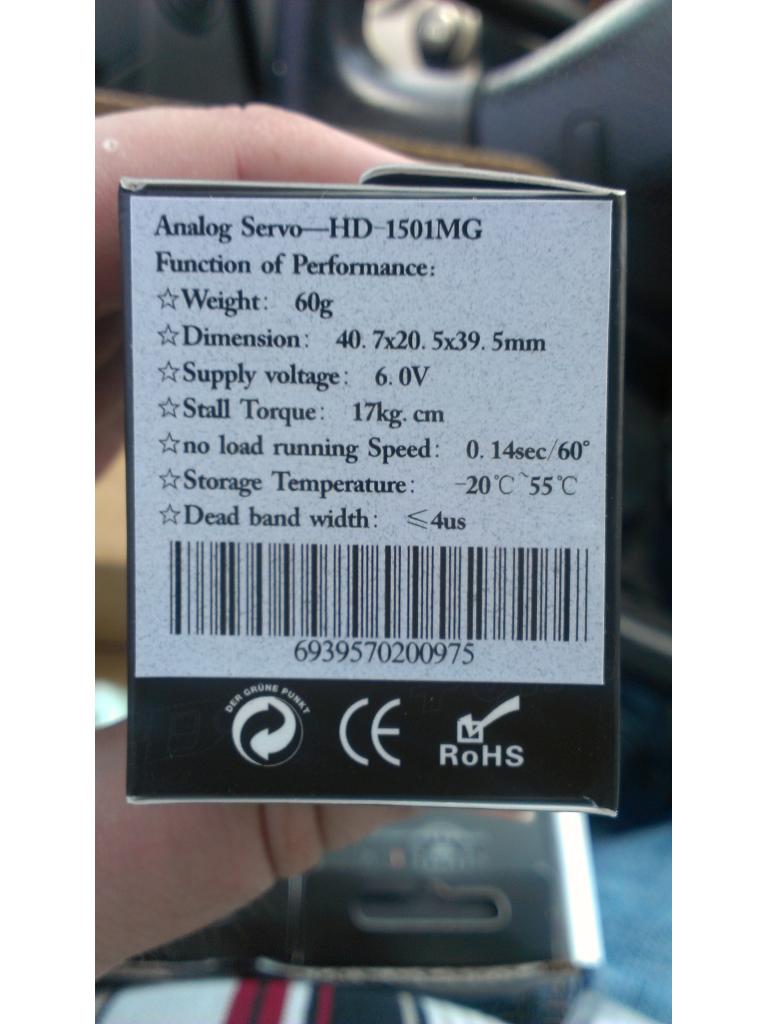
Now that's a goody box!

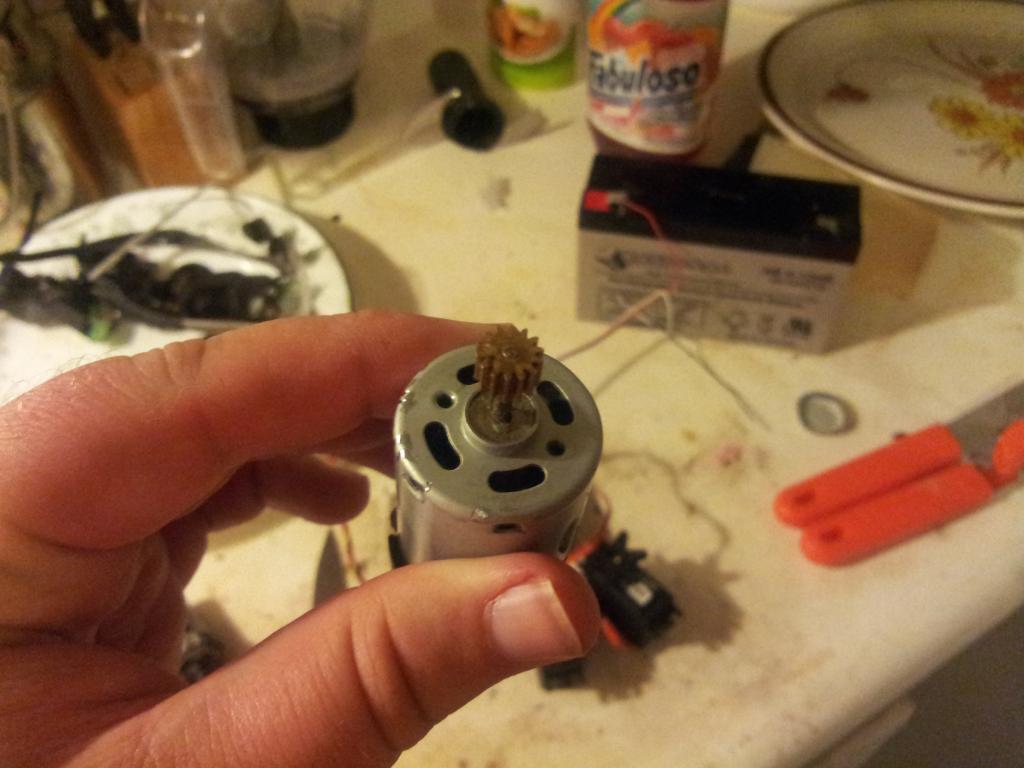
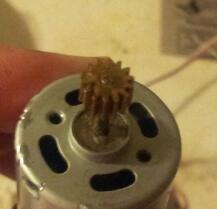
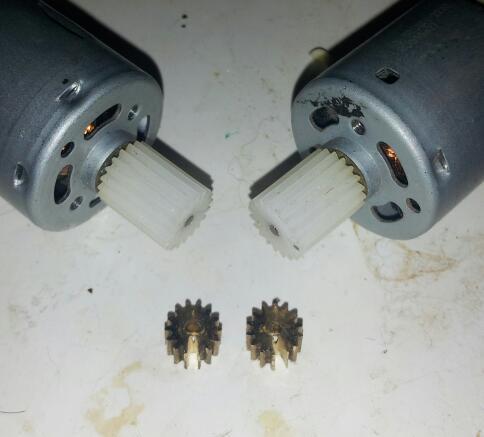
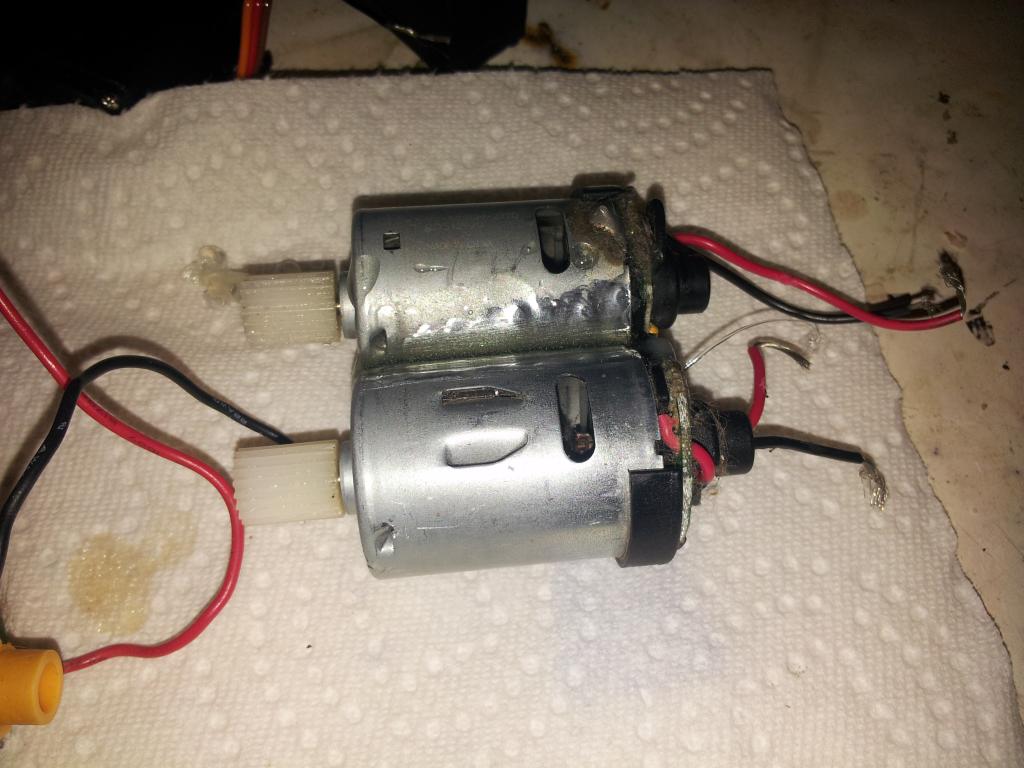
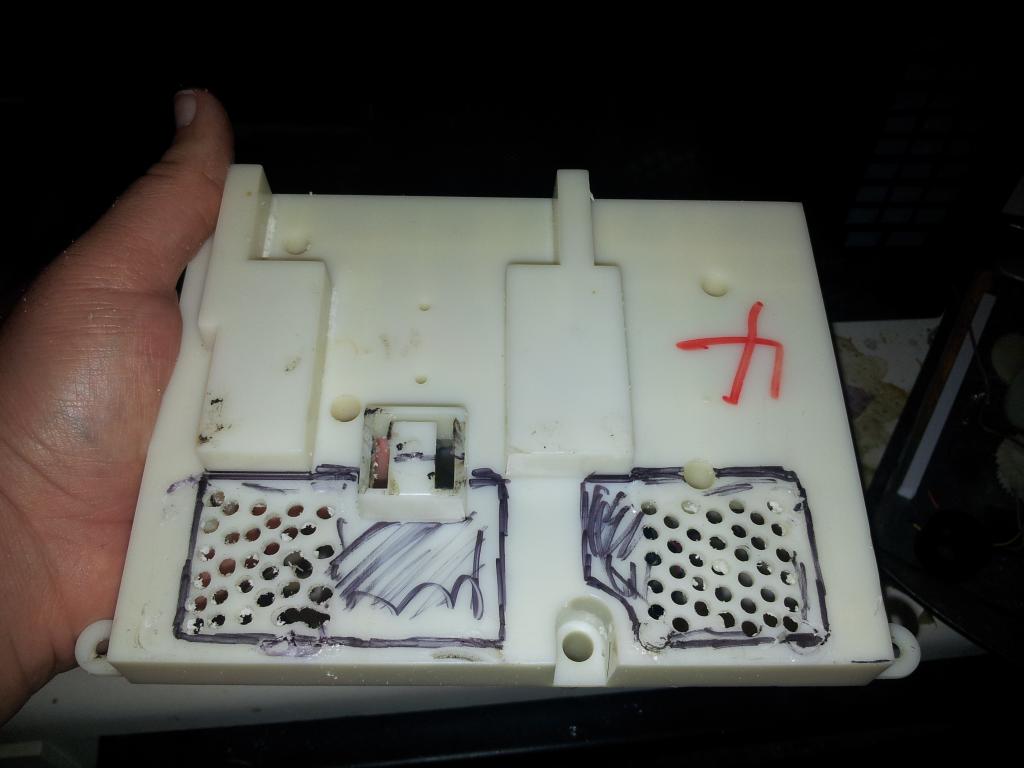
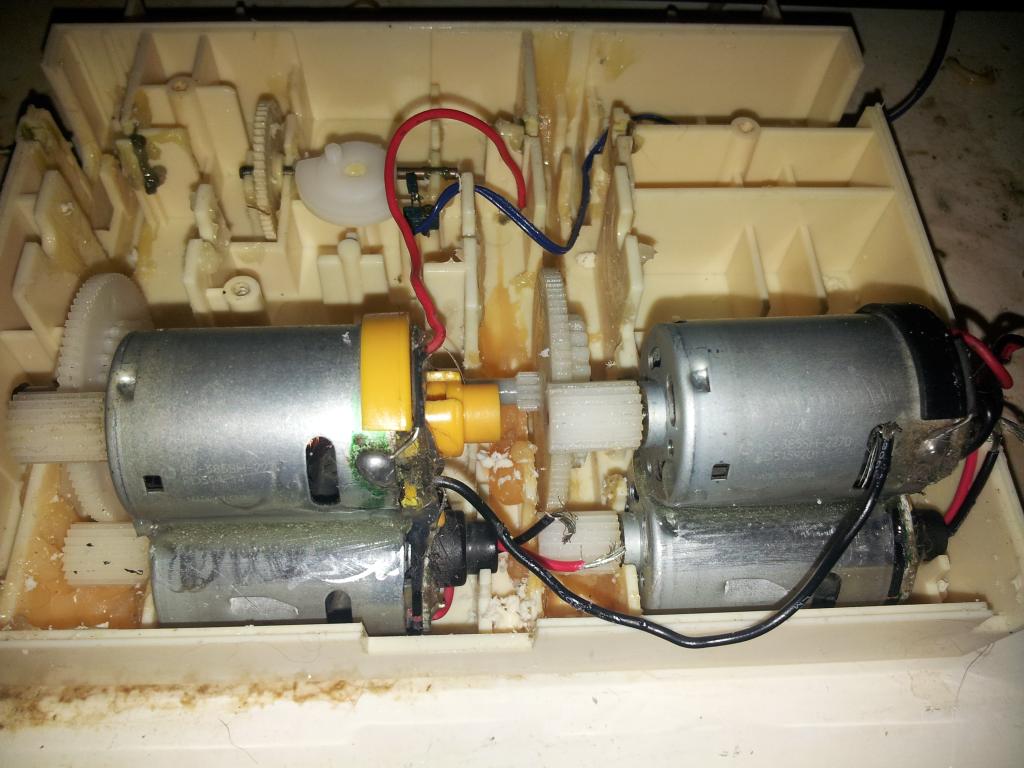
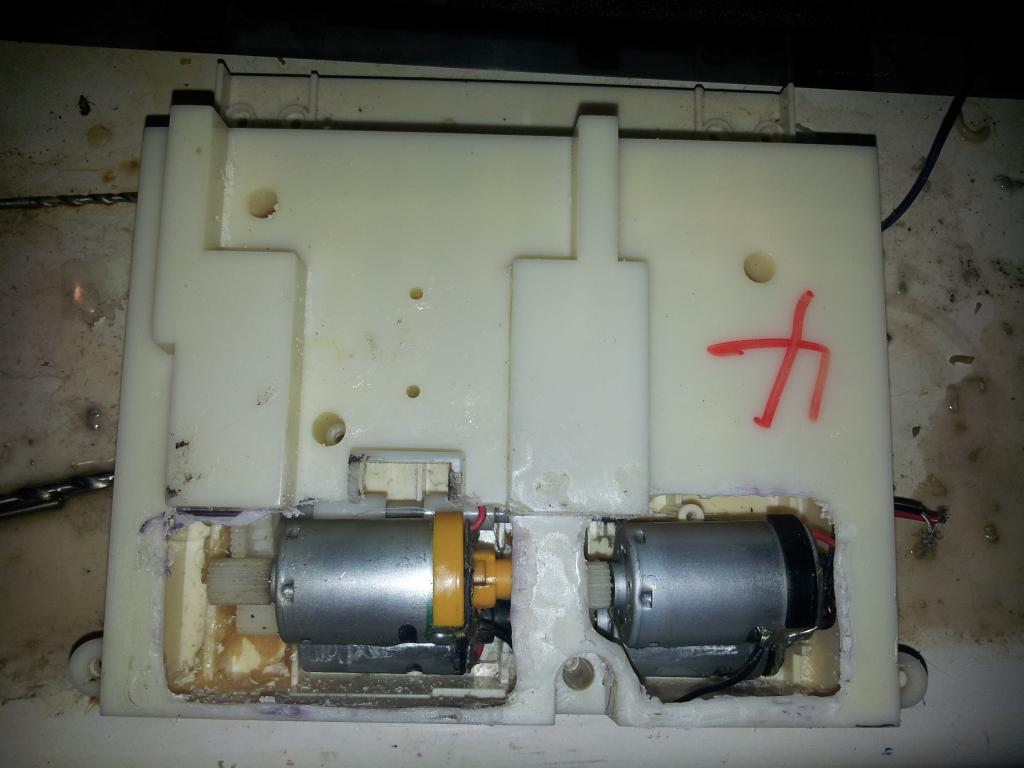
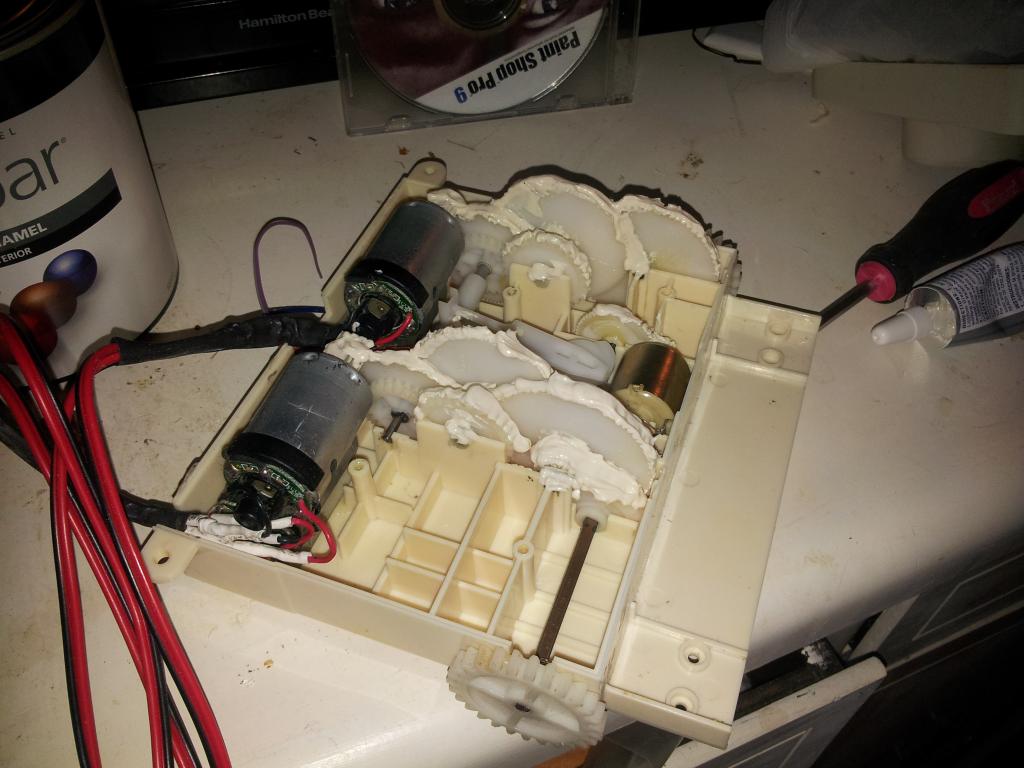
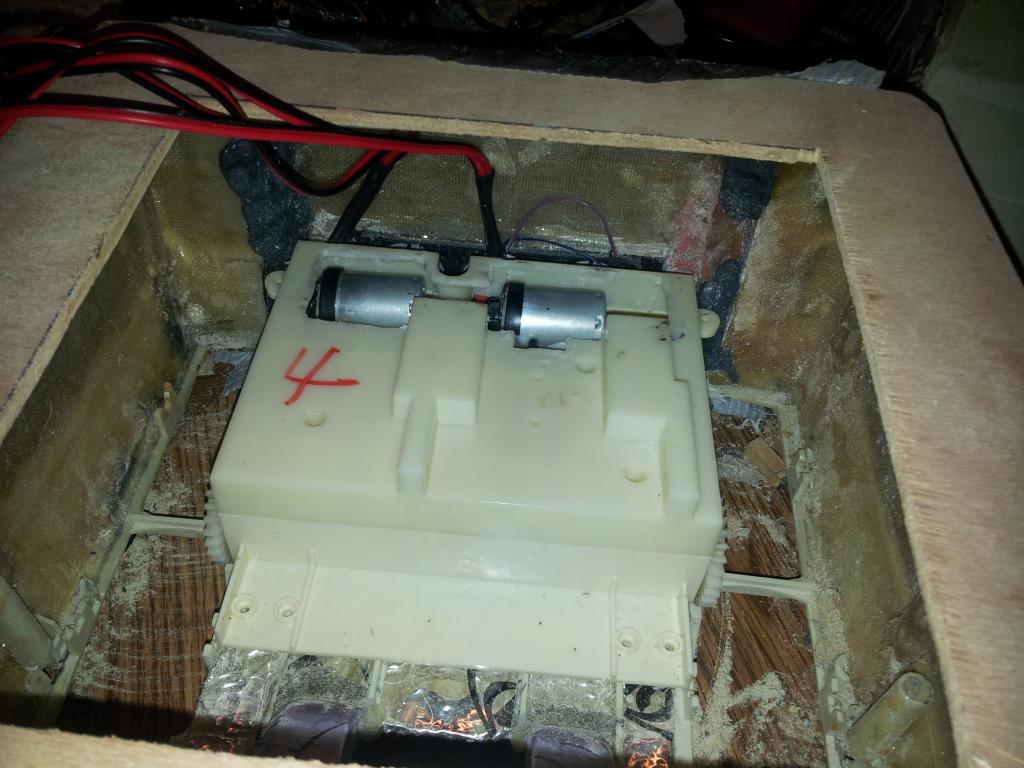
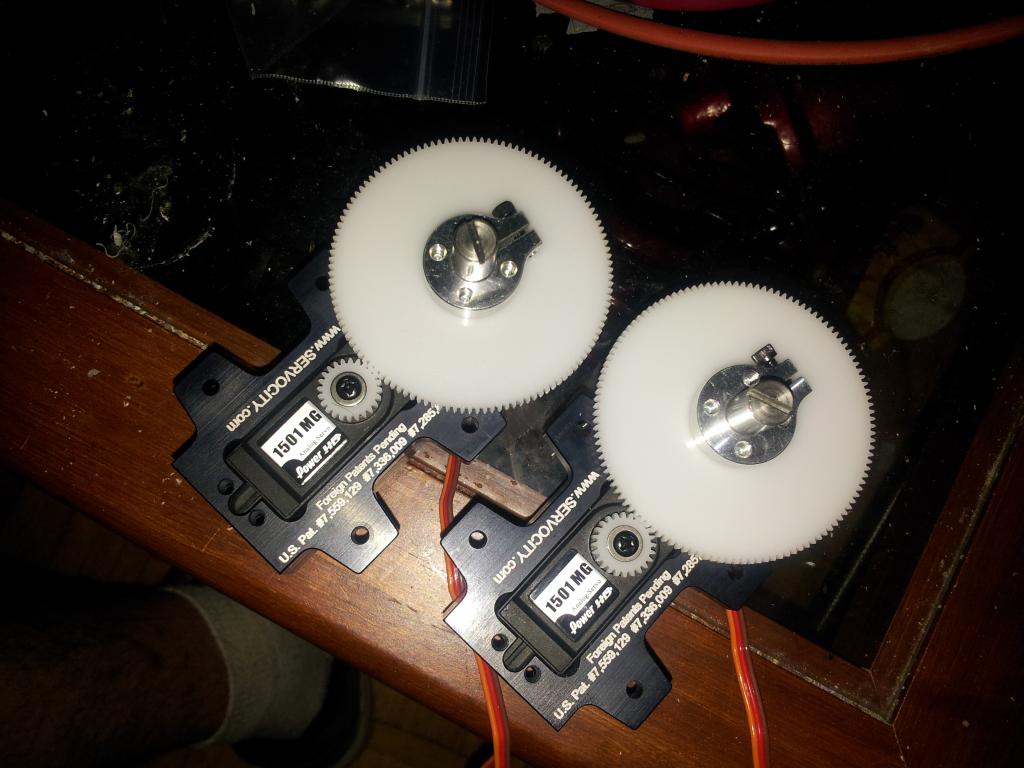
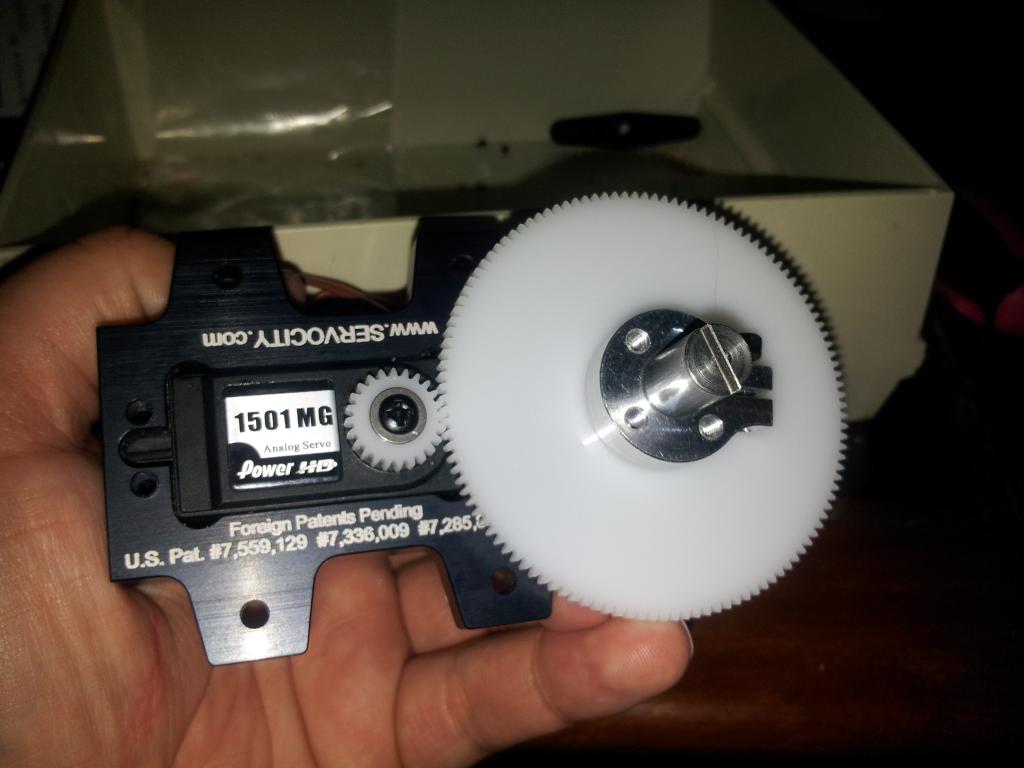
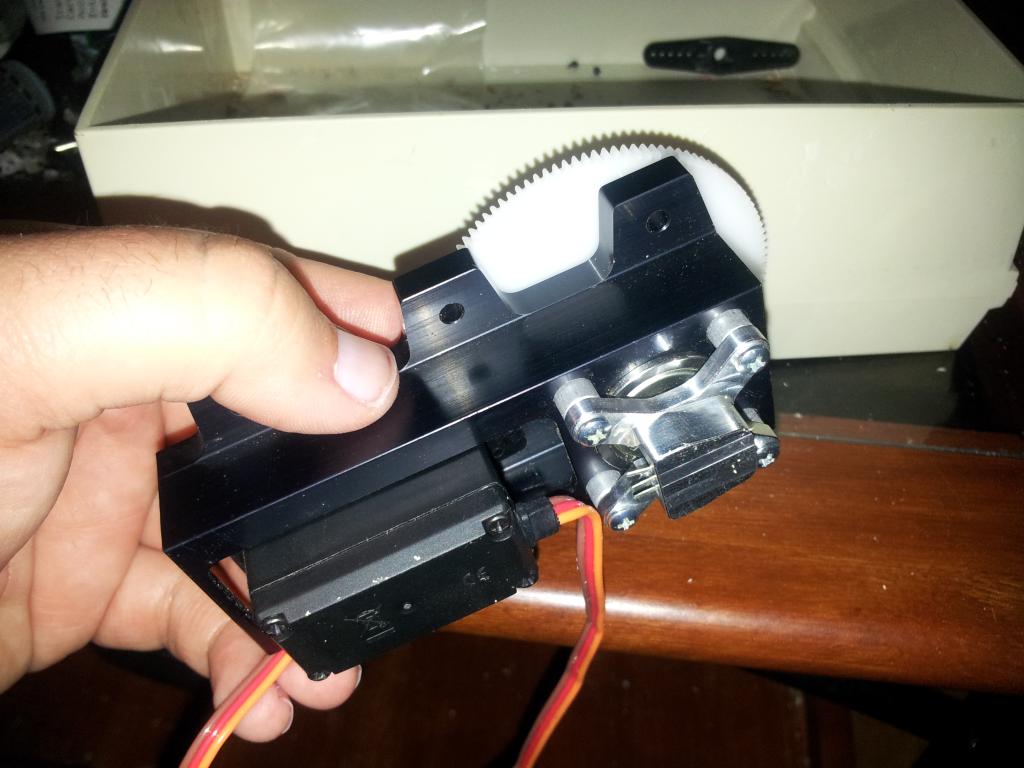
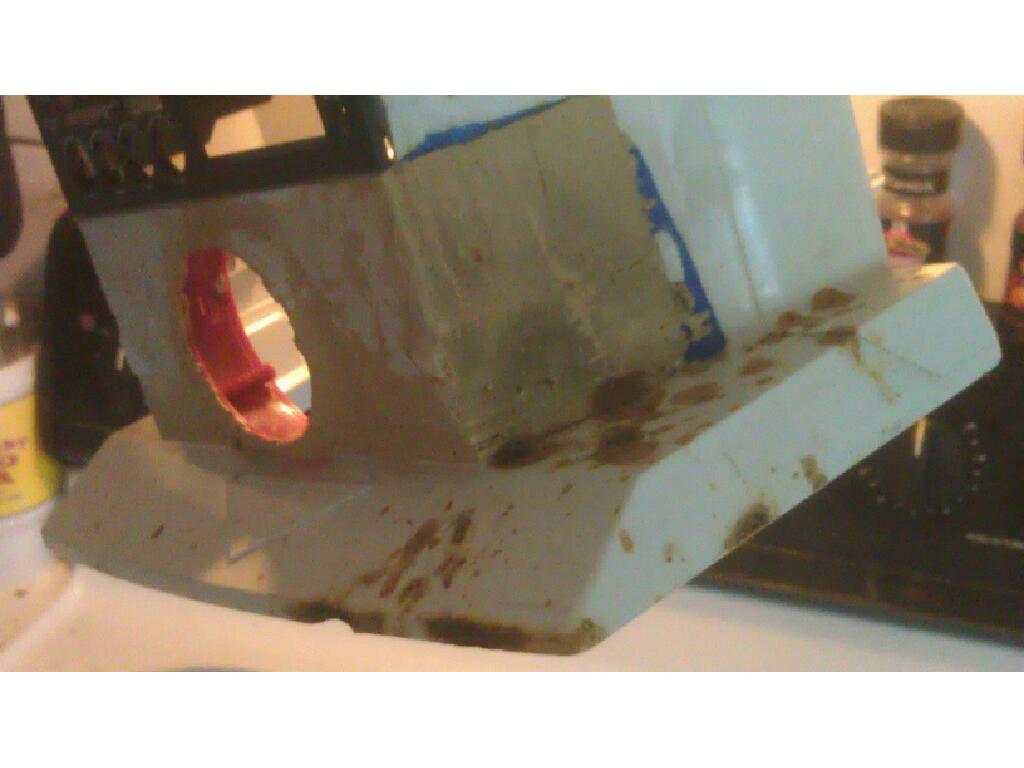
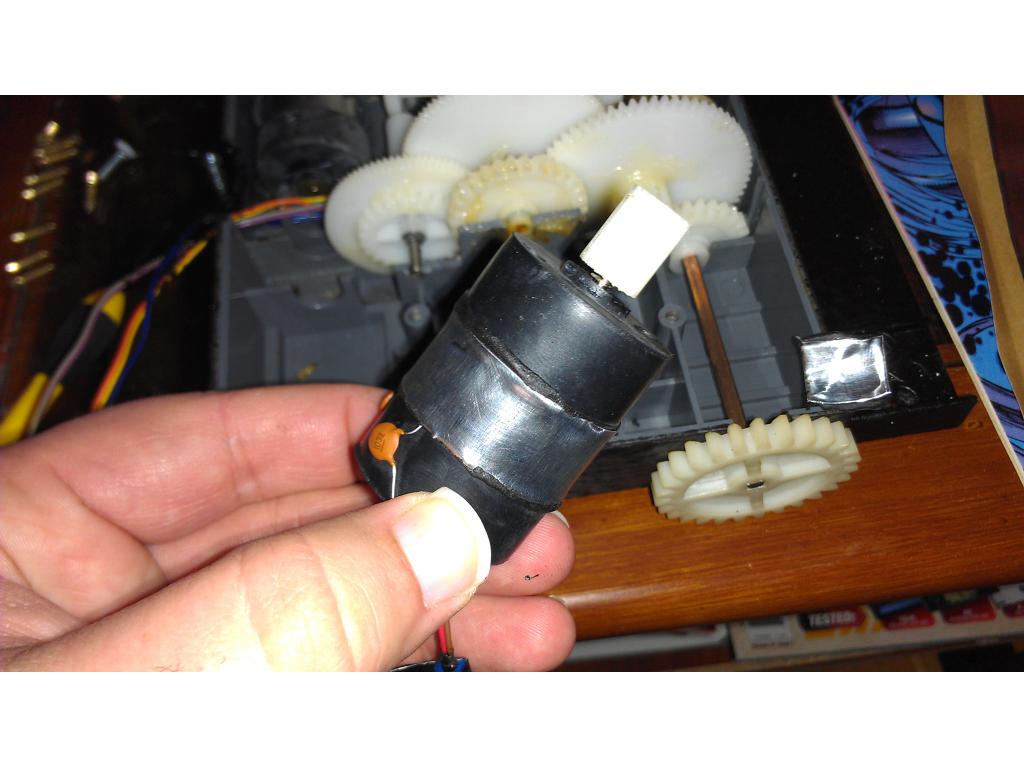
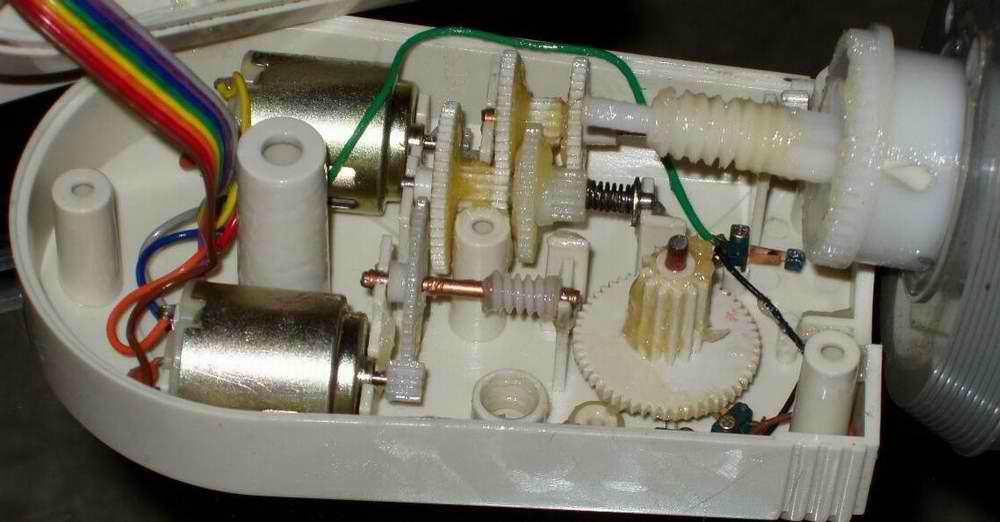
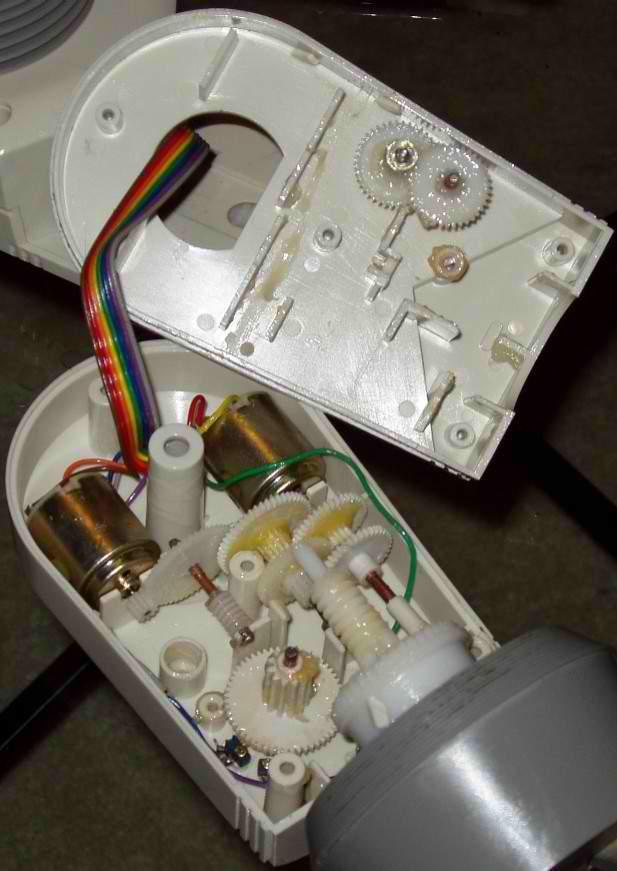
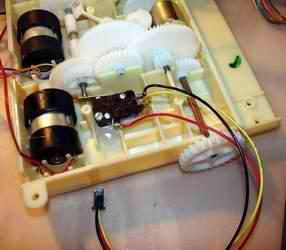
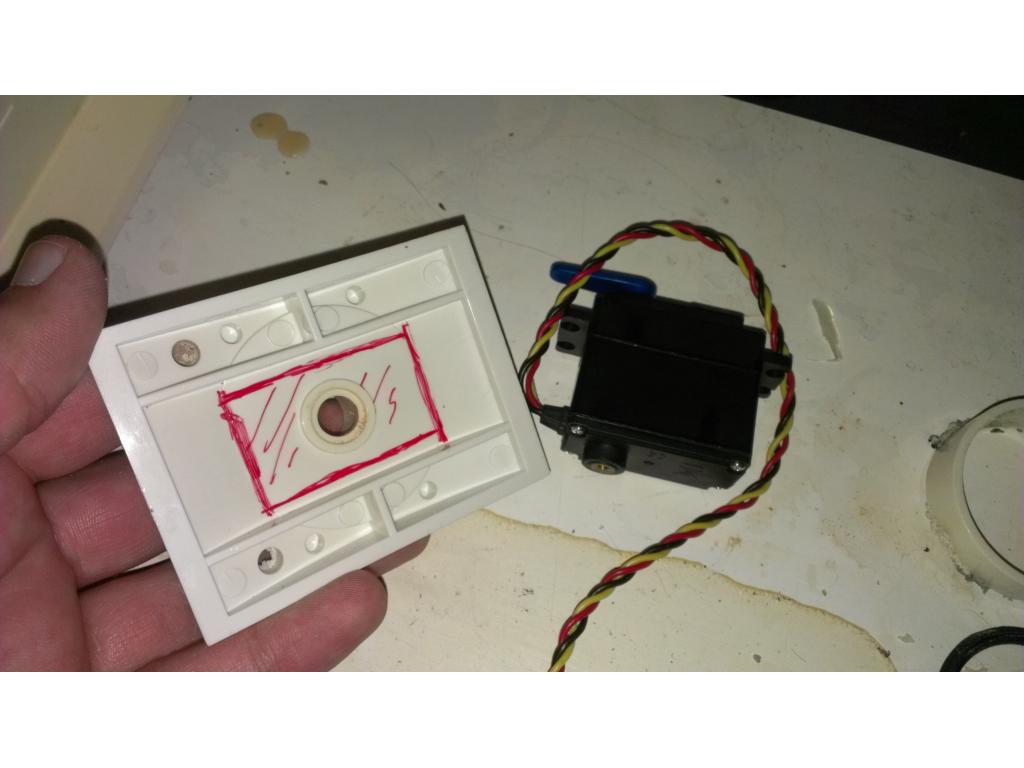
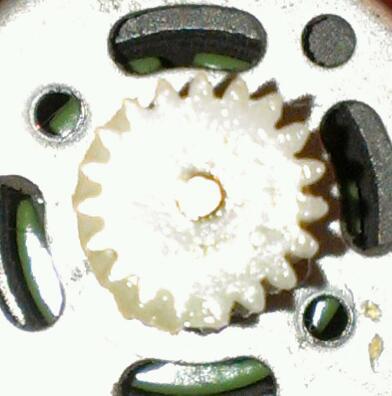
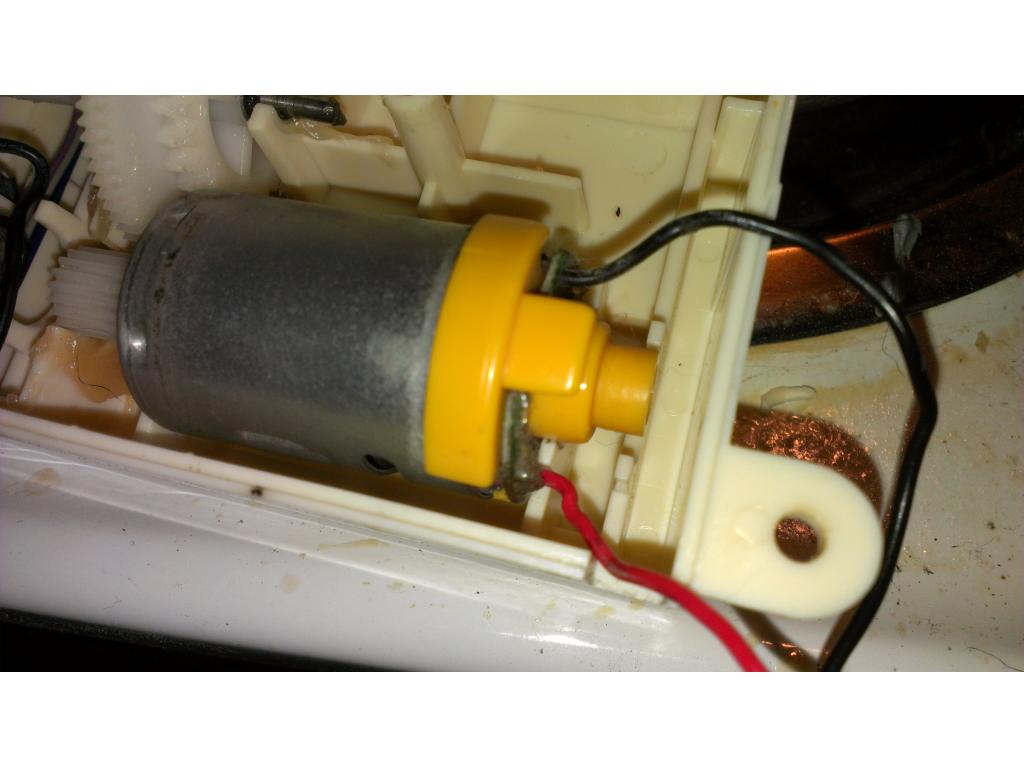
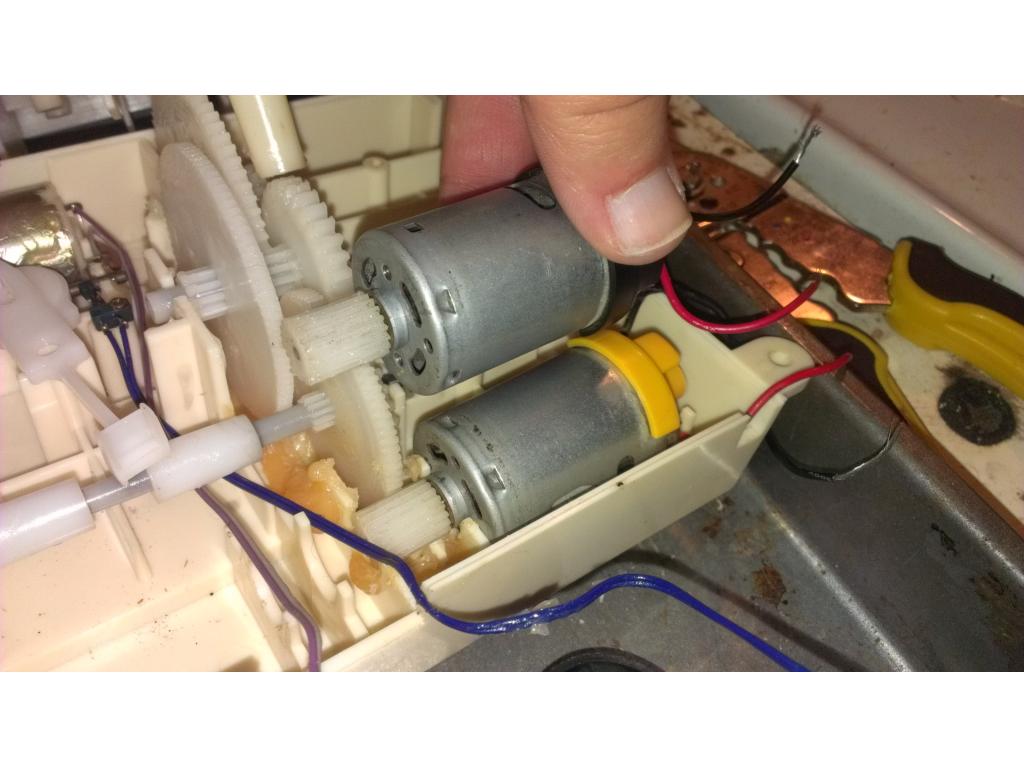
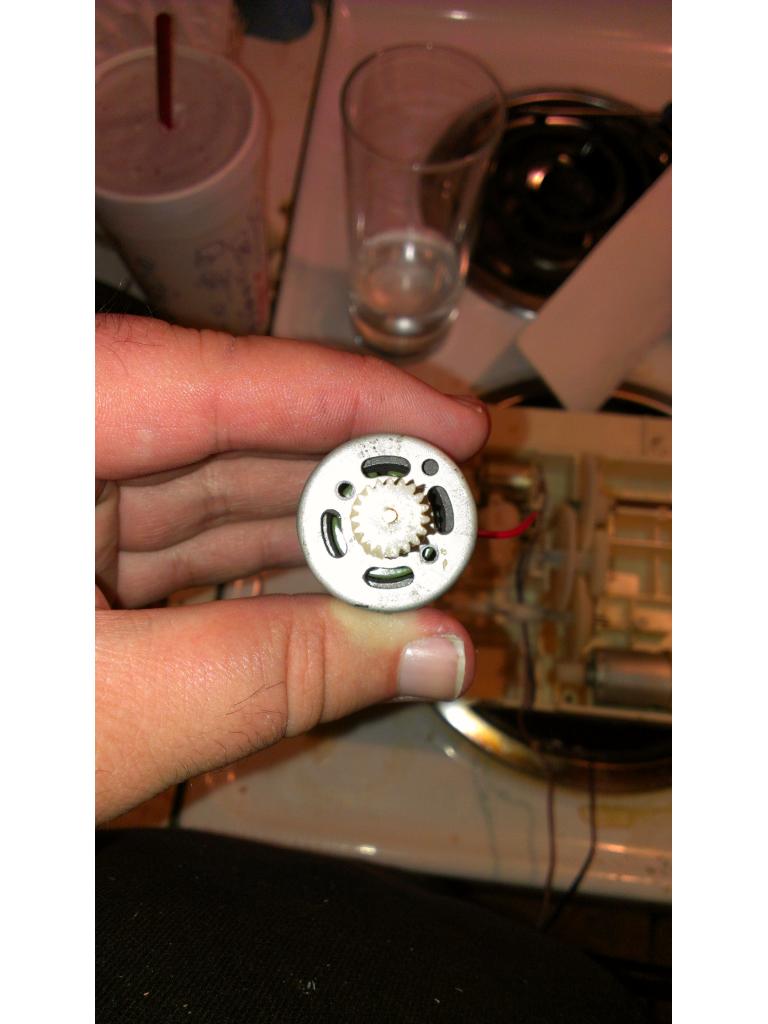
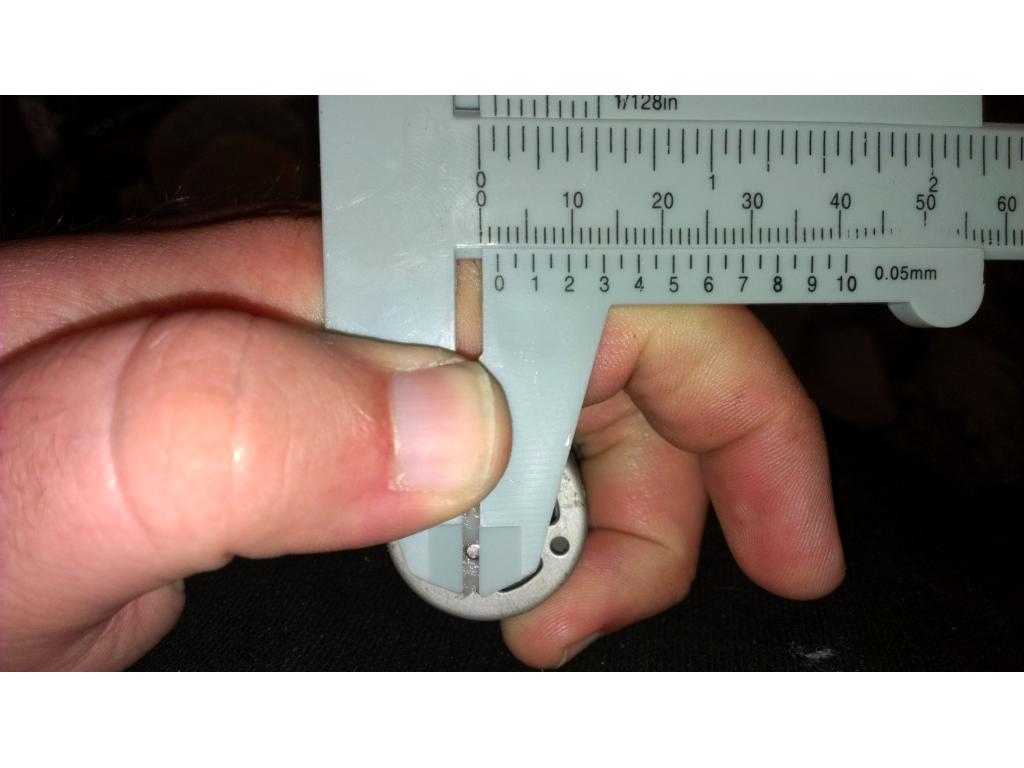
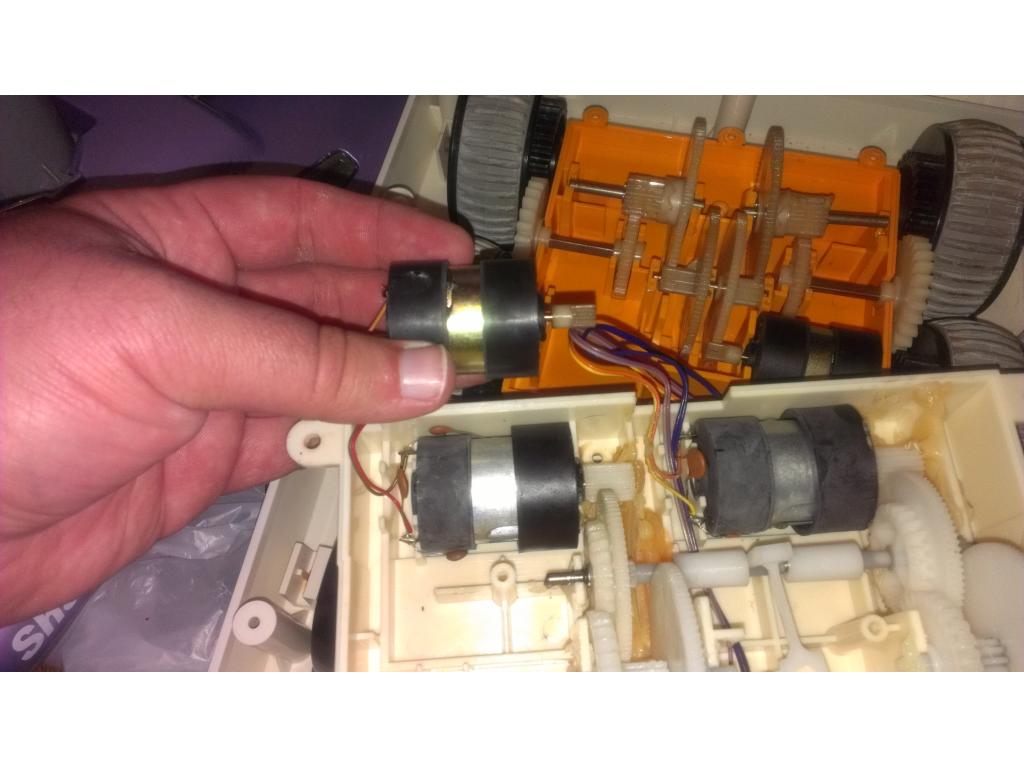
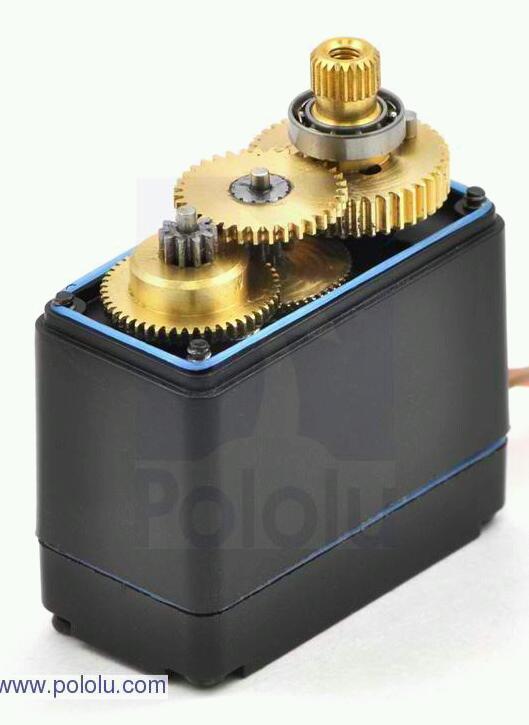
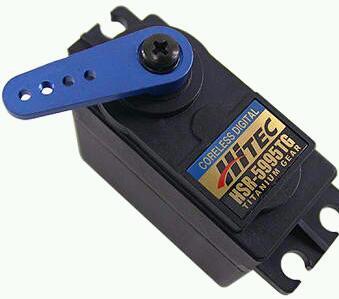
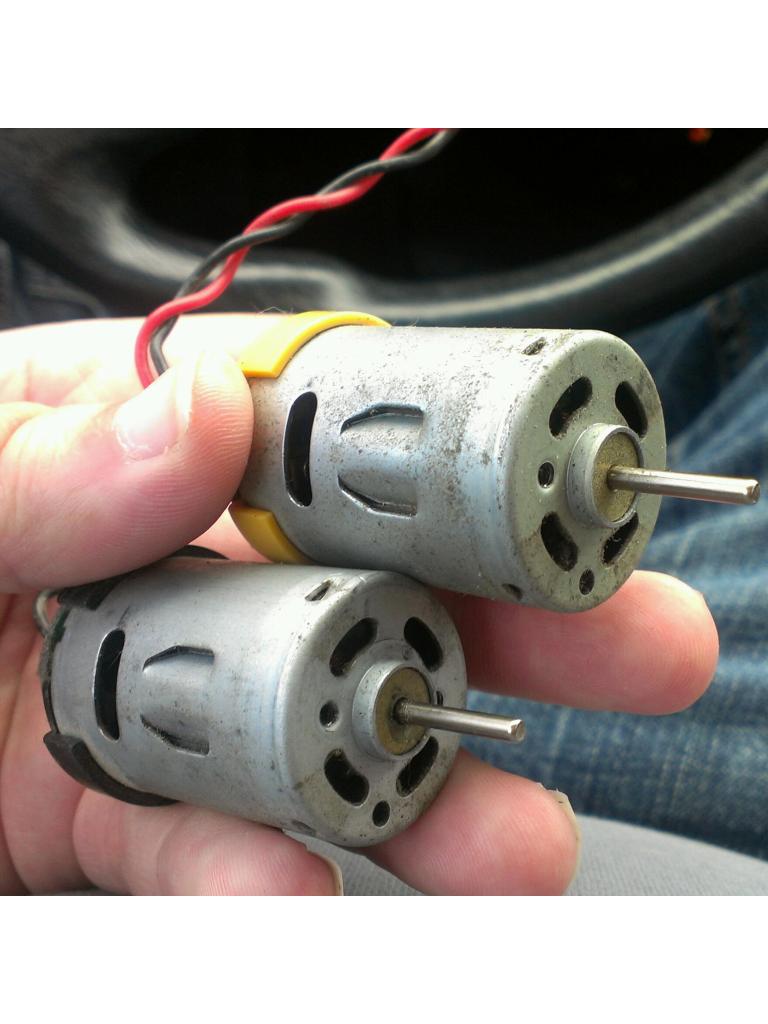
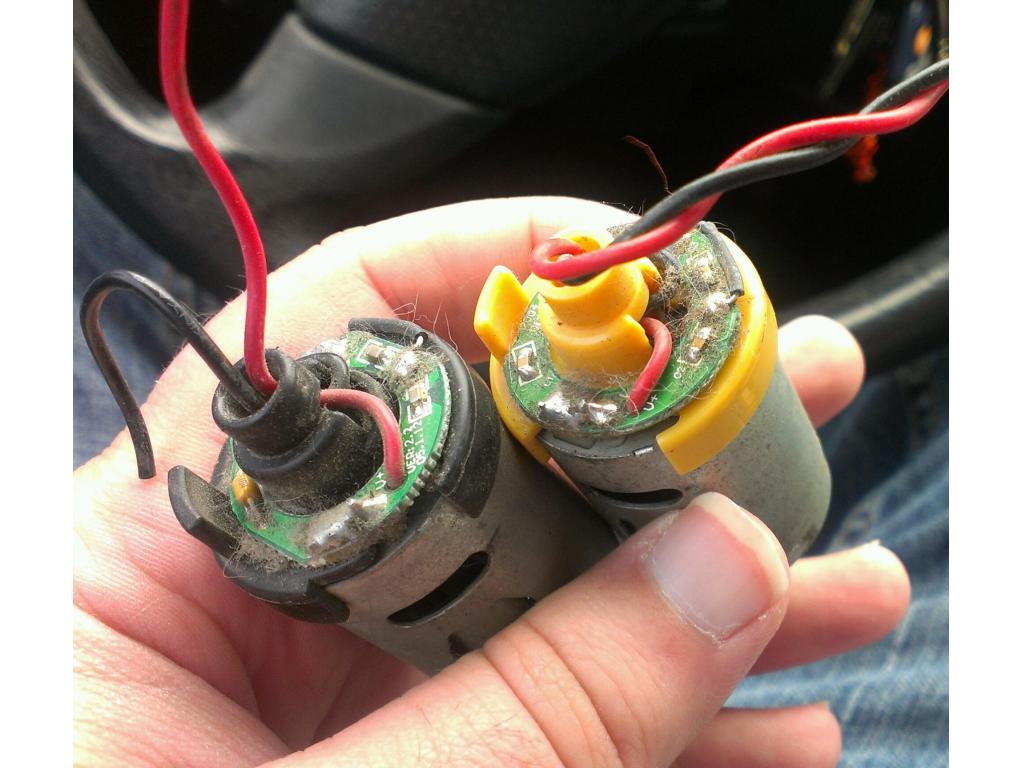
Ok I cut the brass pinions off the shaft which was very easy and tapped on the Delrin pinion from Troy. Next I must cut out the original plastic mounts and adhere two motors together.Ok I cleaned the sides of the motor cases off and cut off the plastic lip so they can be epoxies together. They are.perfect, they are off about a mm but they still line up with the first input spar gear.
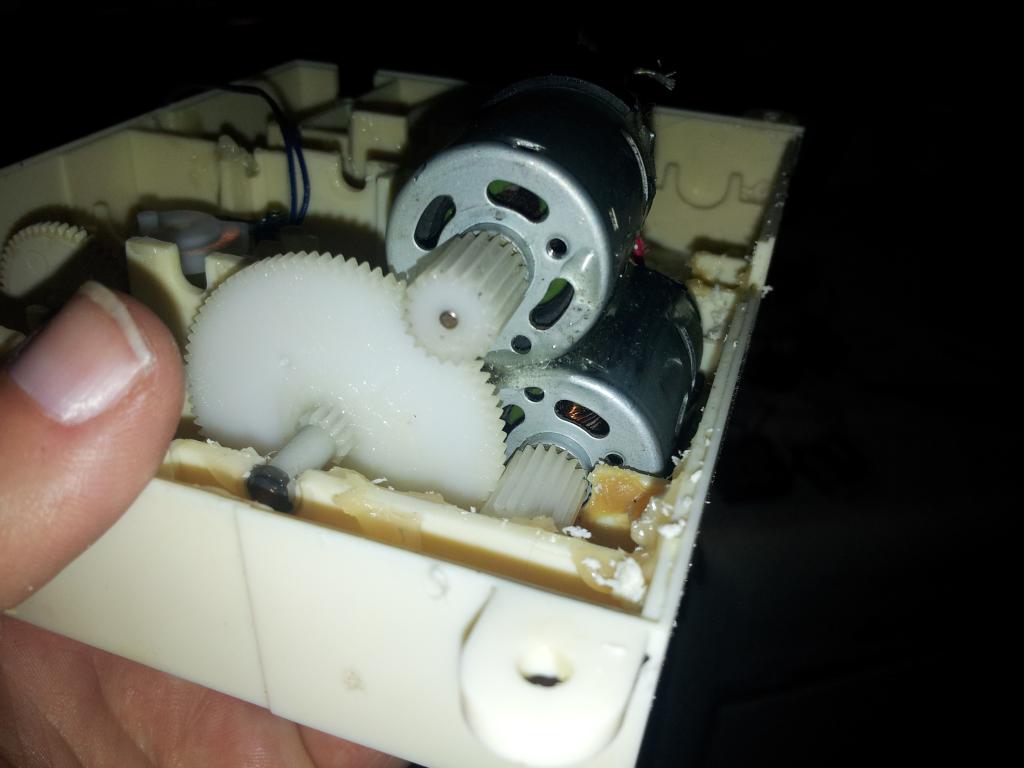
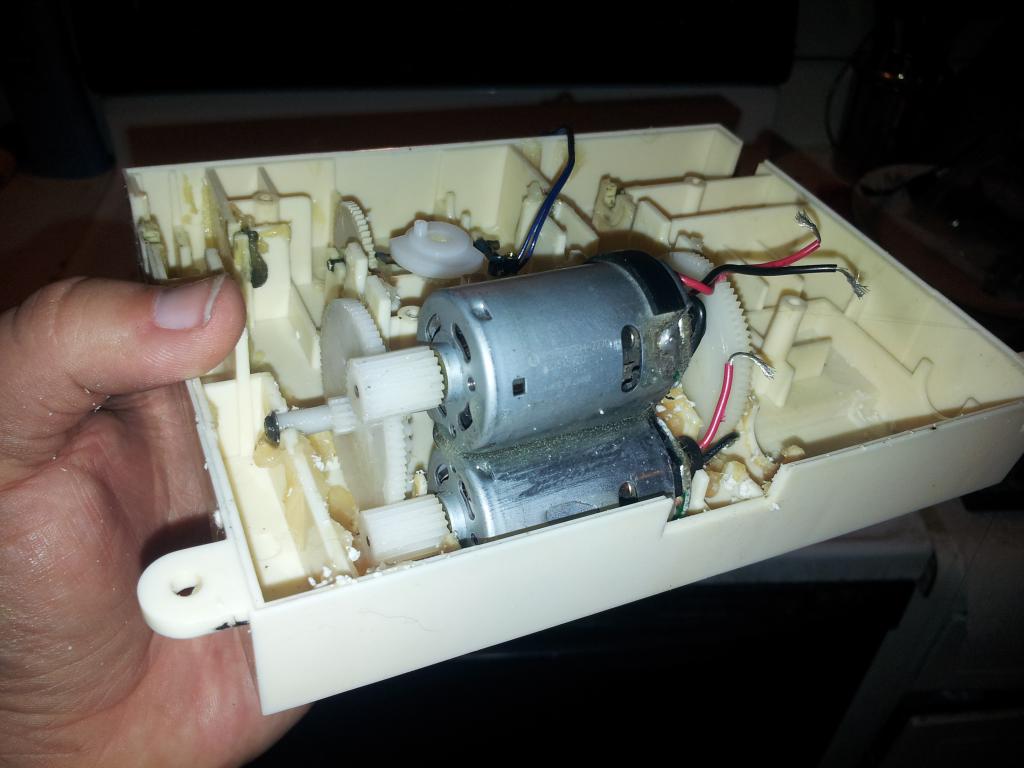
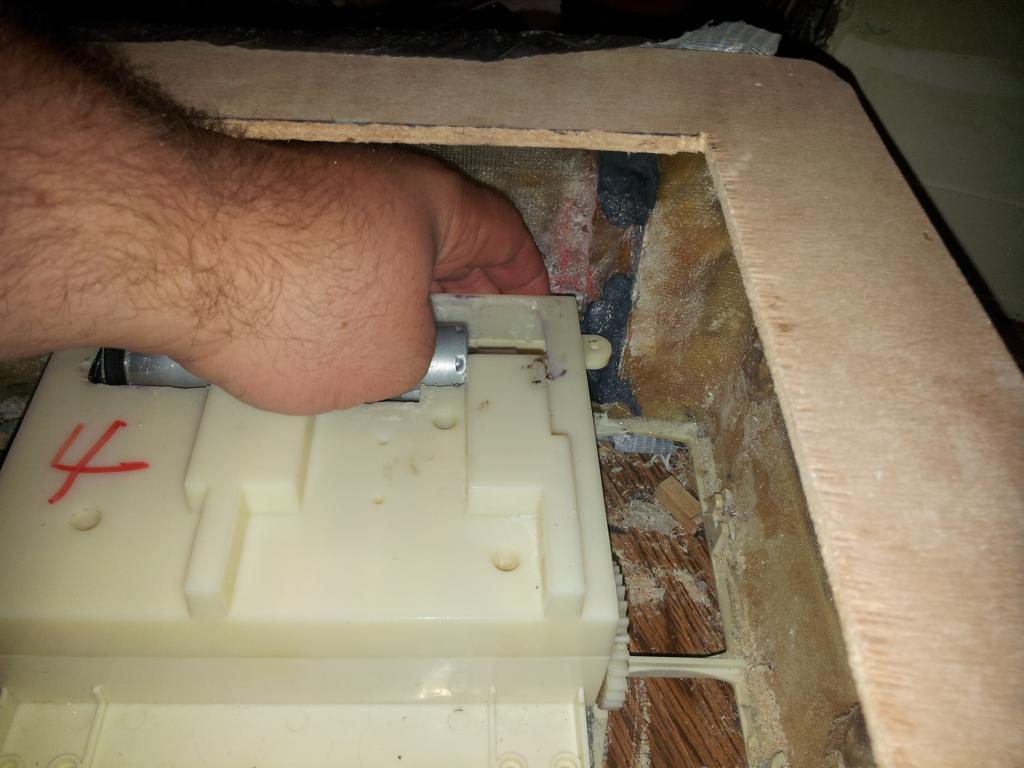
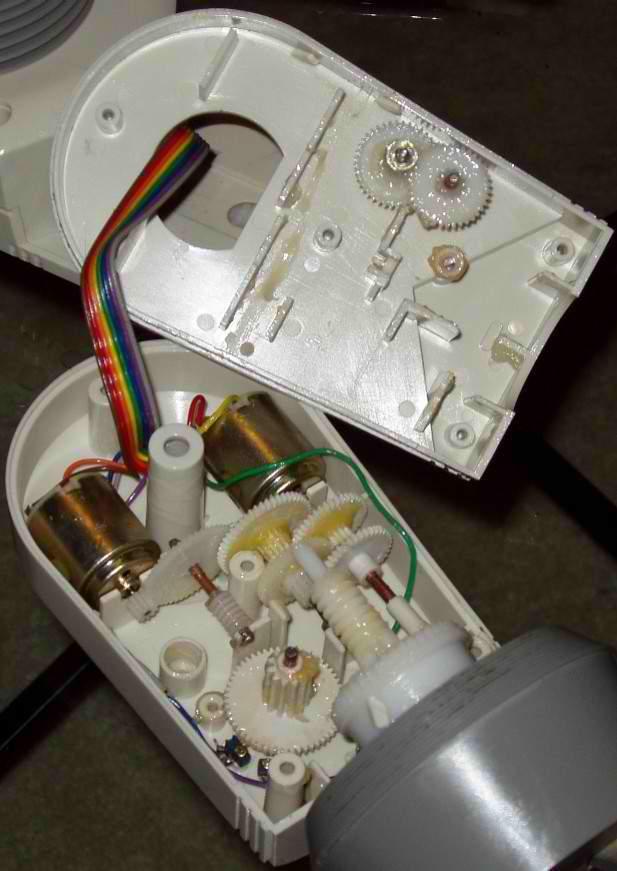
I cut away one mount which was simply too short. Here you can see how two motors would mesh up to the input spargear.
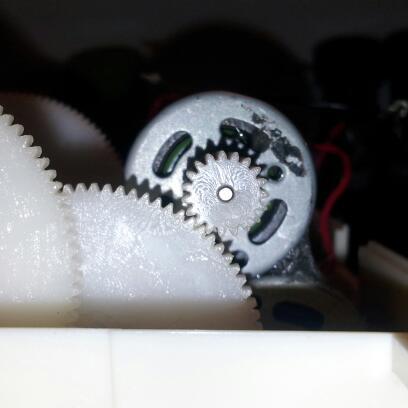
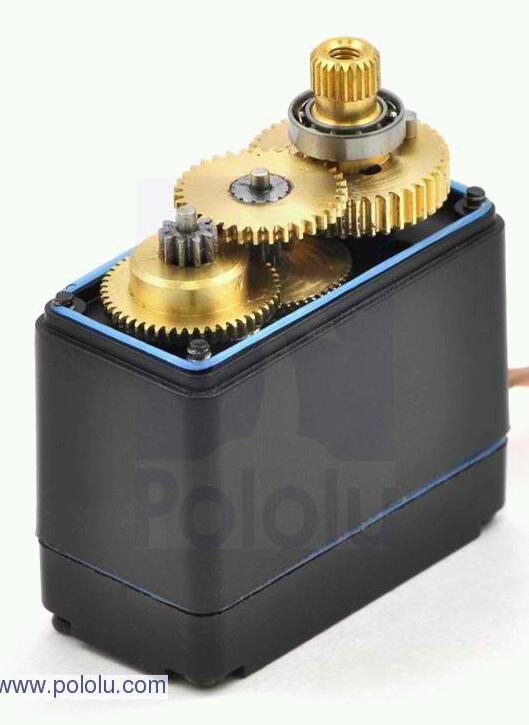
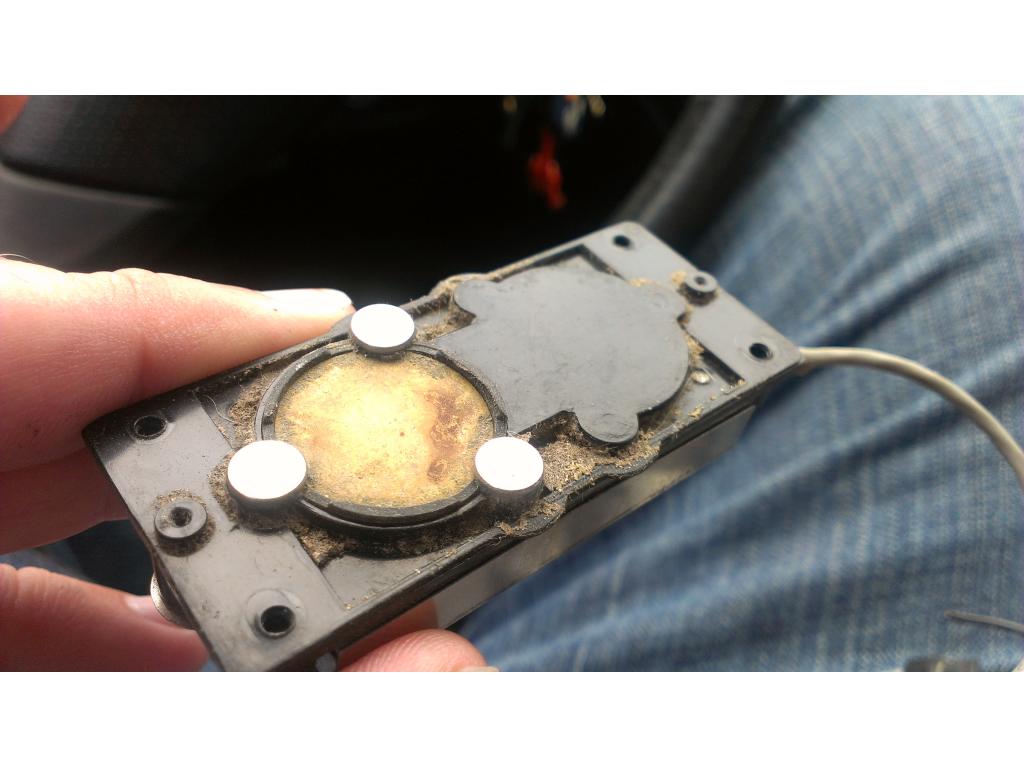
Ok I checked out the meshing on the gears, they look to fit together well. I did a HD test video, sorry about the noise the camera is like 12 inches and sometimes closer to the gearbox which has no grease in it or a cover.
Test video!
https://www.youtube.com/watch?v=Q5w6XiU_3Ho&feature=plcp