a robot that can tell what it sees: I want the robot to drive to an object, snap object's picture, send the pic to a nearby machine (CPU offloading), where the machine predicts the name of the object depicted in the pic via its SAE-DNN model, synthesize the voice file for the predicted name, send the voice file to the robot, where the robot broadcasts the voice via its speaker.
By ms

Discover more robots
Jeremie's Treat-O-Matic 2020
Convert a claw-style candy machine into a contactless Halloween dispenser with Atomic Pi, Arduino EZB, camera, PIR,...
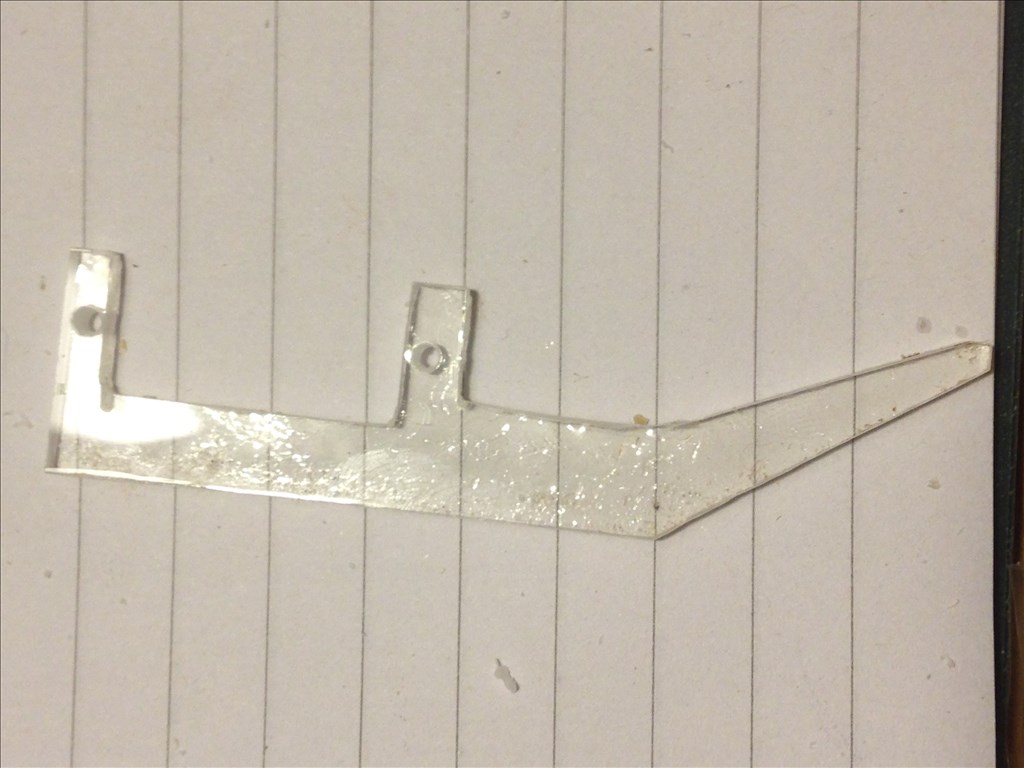
Mgodsell1973's Hexxy - My First Walker
Hexapod walker build with 18 servos, hand-cut parts and calf/foot photos, DIY EZ-Robot Revolution progress and assembly...
Steve's Mini 6 Fabricated Robot
Mini Six EZ Robot with EZB3, micro servos and custom aluminum brackets - compact DIY build with Bluetooth speaker audio...
