


Robot Building Community
Share robot projects, ask ARC programming questions and learn from other builders. Browse tutorials, Robot Skills, example programs and community discussions.
Drive Real Robots, Anywhere
Remotely operate robots around the world or add live telepresence to your own build — straight from your browser.
Discover Exosphere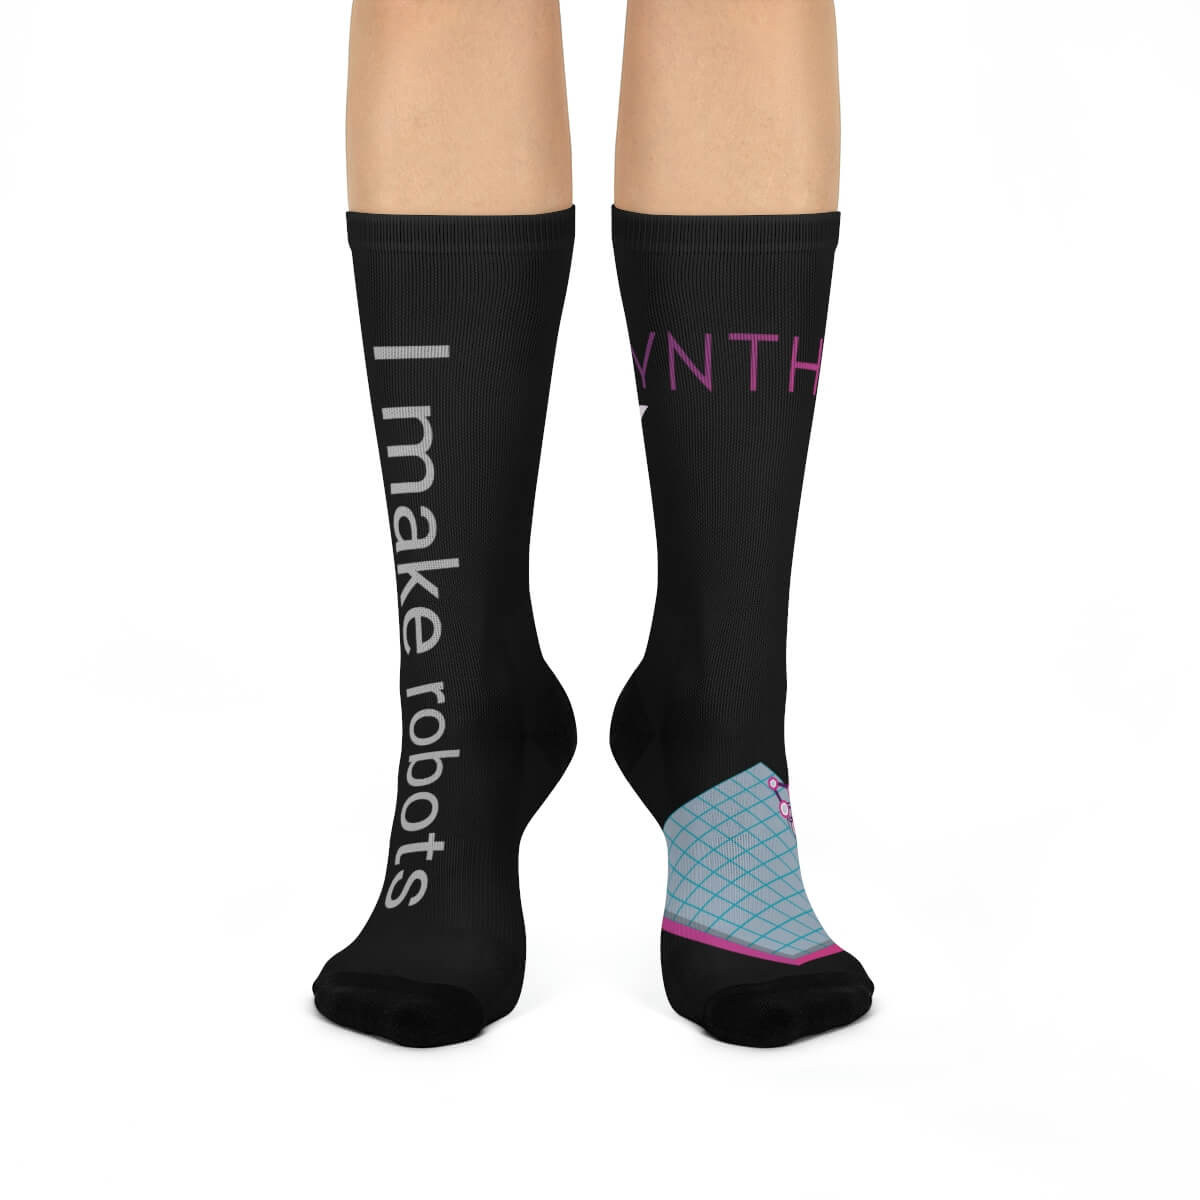
I Make Robots Crew Socks
Autonomous AI
Autonomous AI robot skill with vision, speech, movement, animations, and self-directed task...
Azure Text To Speech
Azure Text-to-Speech for ARC: generate natural-sounding robot speech with Microsoft Azure voices,...
Exosphere
Telepresence and remote control for any robot with human-assisted tasks, video, audio, and AI...
Azure Speech Synthes…
Microsoft Azure neural text-to-speech for ARCx scripts and skills, with multilingual voices, SSML...
Rtk Gps
RTK GPS rover/base skill with NTRIP corrections, cm-level pose, heading support, map fusion, and NMS...
Outdoor Navigator
GPS-driven outdoor robot navigation with satellite maps, saved waypoints, zones, no-go areas,...
ESP32/Arduino EZB firmware with MPU6050 support: provides accelerometer angles and Yaw/Pitch/Roll gimbal servo values for stabilization and scripting
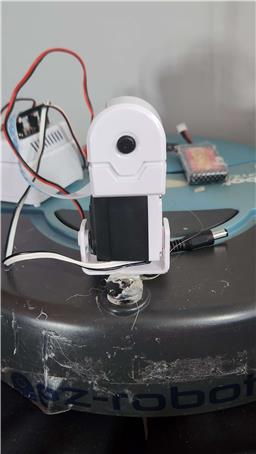
Wiinteru's Blue Irobot Roomba Hack
Hack a blue Roomba using an EZ-B v4 and extension cables; progress made while waiting for correct 7-pin PS2 connectors. 4
 4 k
SSC-32U Pulse Width Modulation
A quick question. If have a couple of 270 degree servos. To get the full rotation I need to set the pulse width range in the SSC-32U configuration to 500-2500. Will this upset other standard 90 degree servos connected to the SSC-32U? The default range on the config was 650-2250, and I was only getting about 220 degrees rotation.
9
2 k
Justinratliff's Walle Built With Iotiny
Updating software and wiring a small non-motorized WallE: servo port mapping, using stock toy switches on one ADC line with resistors.
28
6 k
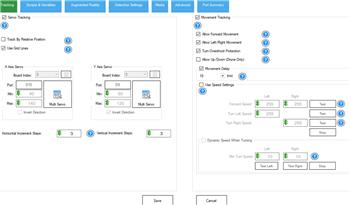
Movement Tracking Not Working
Hello, I have a n issue that I recently ran into and was wondering if anyone had any suggestions on how to fix it. I've been working with my Revolution Roli robot...
10
2 k
Problem With ARC Mobile App Latest Version
I just downloaded the latest version (v2021.05.20.00) of the mobile app to one of my tablets. None of my installed robot apps are appearing. They are still there in the ARC/My Projects directory but don't show up as installed. I downloaded a test project from the Cloud and it seems to store it somewhere else. Do you know what is going on here?
3
2 k
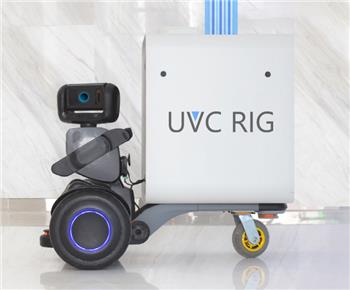
Loomo Segway Support?
HI, Just found you guys, Love it! Any Chance Loomo Segway works with ARC? Update: I know I posted the question without good information of what I am attempting. My final goal is...
34
8 k
Auidio Toolbox Plugin And Soundservopc Speaker Control
Has anyone come across this problem. If I use the AudioToolbox plugin to add more voices to my project...
4
2 k
UART Javascript Help
While programming a little bit of this and that over the years and understanding the concepts of programming, I'm actually not that well-practiced. Syntax and nuances usually get me. I have gone over the Javascript UART section up and down but couldn't find the answers I was looking for. While doing some UART Javascript code, sending a packet of...
7
2 k
PWM Frequency Range
What is the default PWM frequency of the EZ-B v4, and is it adjustable? I'm sorry; I should been more precise in my question. Here is what I do know; In a conventional analog servo motor a PWM signal with a period of 20 ms is used to control the motors. A signal of 20 ms has a frequency of 50 Hz. The width of the pulse is varied between 1 and 2 ms...
6
2 k
Ohmnilabs Standalone v15
Connects Ohmnilabs Telepresence robot's UP Board COM to ARC, enabling drive and servo control (neck V0) and integration with ARC cameras.
0
84 k
Afcorson's Counting Rotations Of A Parallax Feedback 360 Degree Servo
Specify Parallax Feedback 360 servo rotations using ADC0 feedback; D0 servo control script counts rotations for precise multi-turn moves.
0
3 k
How To Send JSON & Set Header Request On Net.Httppost() Method?
Hi everyone, I'm using Net.hTTPPost(url, postData) method on ARC script (JavaScript). I've...
9
3 k