Change Release Notes
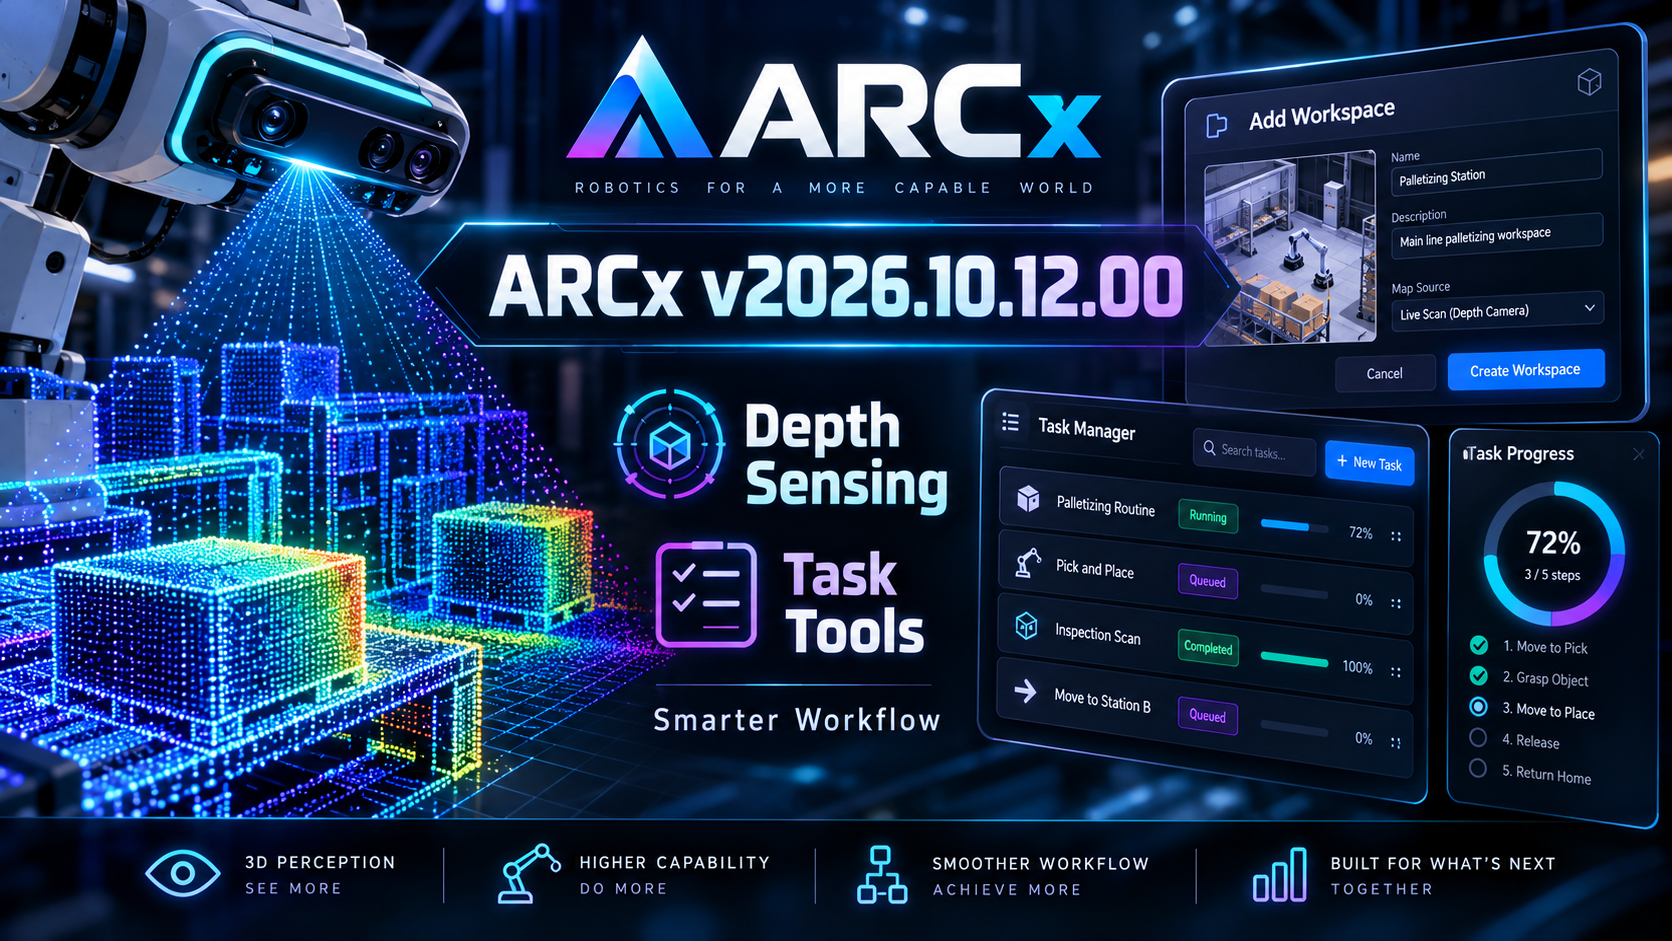
ARCx 2026.10.12.00 is all about making your day-to-day workflow smoother while quietly leveling up what your robots can see and do. This release brings smarter workspace and task tooling to the UI, introduces a brand-new Depth Sensing service for depth cameras, and includes key reliability improvements (plus a few quality-of-life updates for docs, installer, and developer workflows).
Workspace & UI upgrades
New "Add Workspace" dialog
- Added
UCAddWorkspaceDialogto make creating a new workspace fast and friendly. - Includes title validation so you can’t accidentally create an unnamed workspace.
- Added
Layout integration + consistency improvements
- Updated
MainLayout,AnonymousLayout, andCustomUILayoutto integrate the new workspace flow and keep behavior consistent across views. - Refactored layout structure to remove unnecessary dependencies and improve overall cleanliness and responsiveness.
- Updated
Updated styling
- Refreshed
arcx.cssto match the new UI components and layout changes.
- Refreshed
Built-in Task Management components
New task-focused UI components were added to help track and visualize work inside ARCx:
- Added task management components including:
UCTaskChartUCTaskManagerUCTaskRing
- Added supporting task management service classes to back these new UI elements.
New: Depth Sensing service (Depth camera support)
ARCx now includes a dedicated Depth Sensing service to better support depth-enabled robotics projects:
- Introduced the
DepthSensingservice and core components, including:DepthSensorDepthFrameDepthSensorService
- Updated the project to include the new depth sensing components.
- Documentation updated to reflect the new depth camera capabilities and service integration.
Movement Manager reliability improvement
- Improved
MovementManagerServicehandling of custom movement switching- ARCx now detects changes in both custom movement ID and speed, preventing cases where switching movements at the same speed could fail silently.
Developer & power-user improvements
New command-line option
- Added
--no-browserto the command line documentation, allowing ARCx to start without automatically opening a web browser.
- Added
Cancelable build & upload operations
- Added a
CancellationTokenparameter toBuildAsyncandUploadAsyncinRobotSkillDeveloperService.csfor better control over long-running async tasks.
- Added a
Port enum safety fix (PWM/ADC and more)
To prevent incorrect usage and improve reliability:
- Removed the
[Flags]attribute from these enumerations so ports aren’t mistakenly treated as combinable bitfields:ADCPortEnumDigitalPortEnumPWMPortEnumServoPortEnum
Documentation updates
- Updated and expanded manuals/guides to cover:
- New workspace and task-related UI additions
- The new
DepthSensorService(including updates inRobotSkill-Services-And-Core.md) - Updated
RobotSkillAiPrompt.csto reflect current service availability
- Corrected URL HTML entity representation in
McpGuides.cscomments to improve guide clarity.
Installer & versioning
- Updated Windows installer configuration (product version and identifiers) to ensure installs match the latest build and release packaging.
Download ARCx
Install ARCx on the computer that runs your robot — from a first prototype to a commercial product or an industrial cell. Available for Windows 64-bit, Linux 64-bit and Linux ARM64 for Raspberry Pi (Ubuntu 24.04 LTS 64-bit).
Linux
Ubuntu, Debian & friends
64-bit (x64) (zip)
Raspberry Pi
Single board computers
Linux ARM64 (zip)
Requires Ubuntu 24.04 LTS (64-bit)
ARCx is always evolving. Follow along in the community for updates.
Follow ARCx development Download ARC today
Upgrade to ARC Pro
Unleash your robot's full potential with the cutting-edge features and intuitive programming offered by Synthiam ARC Pro.