


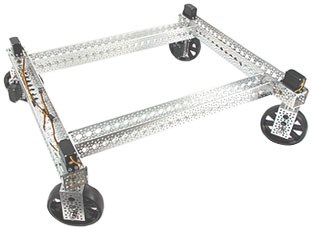
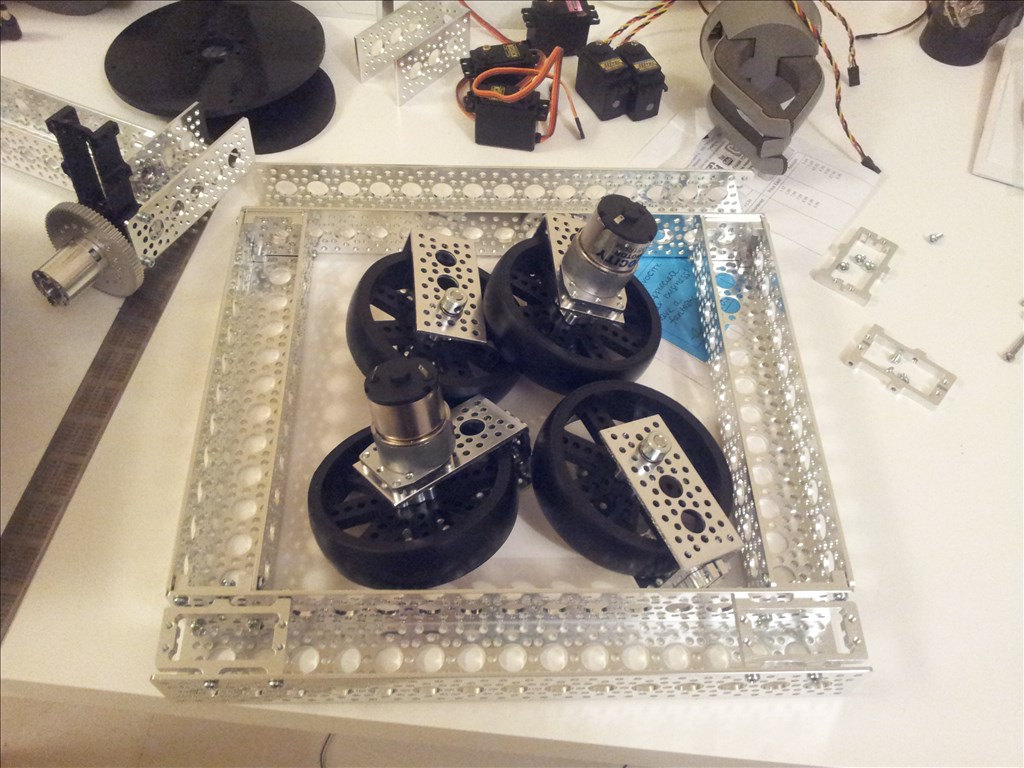
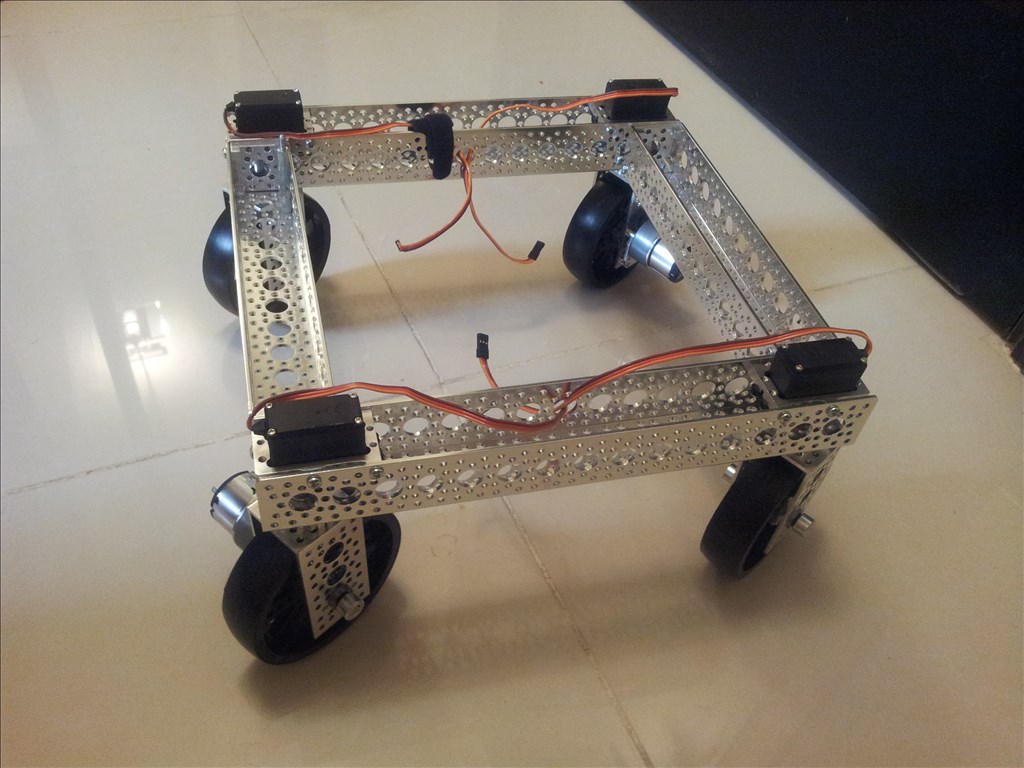
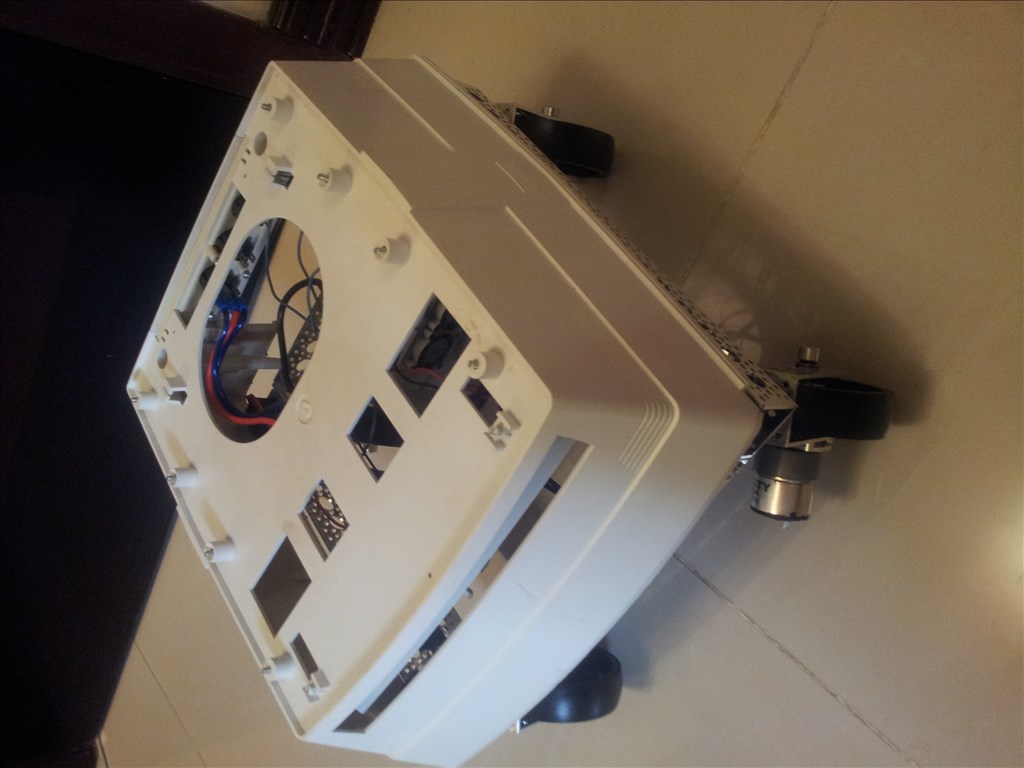
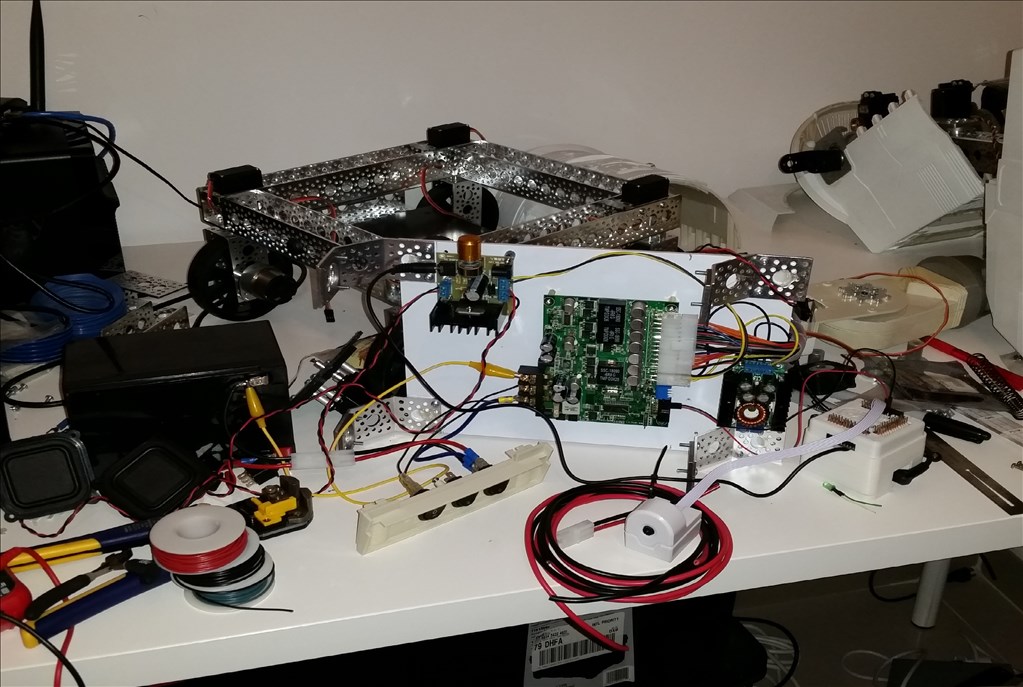
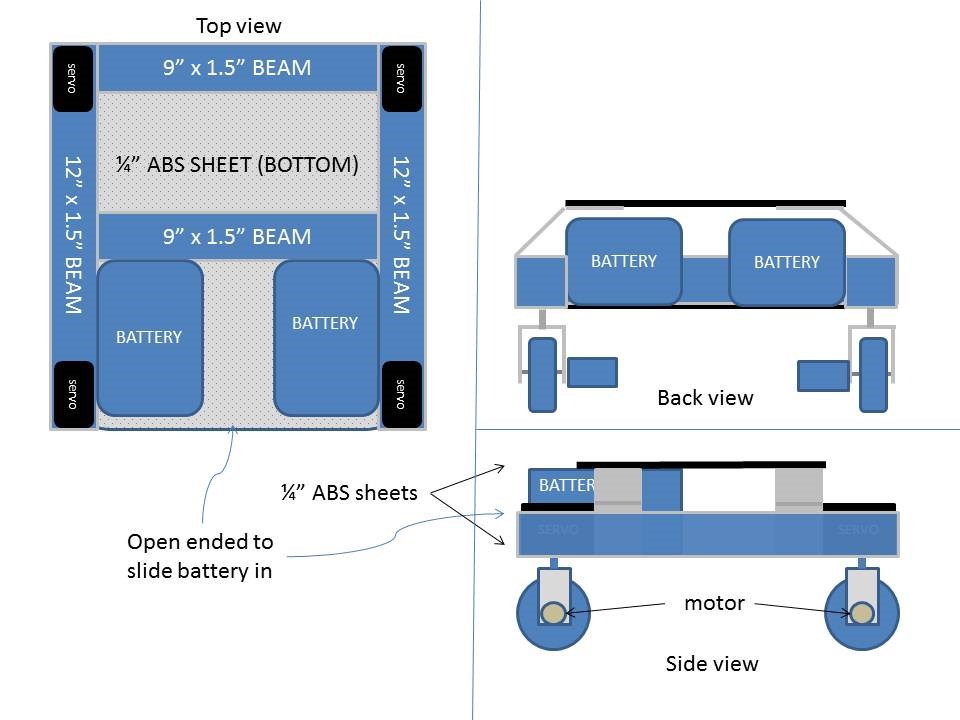
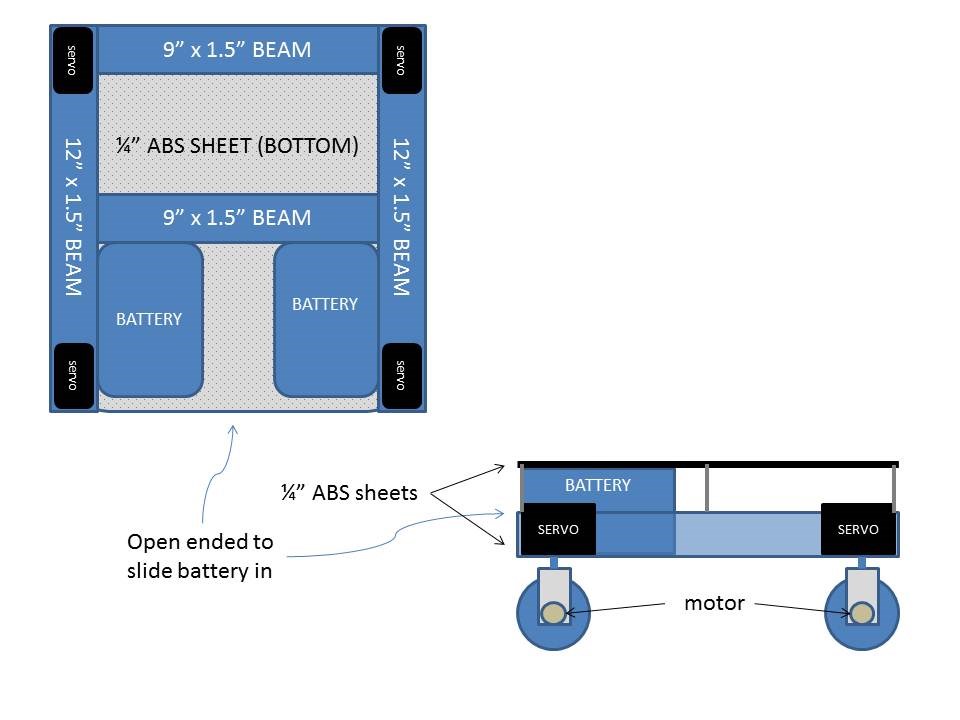
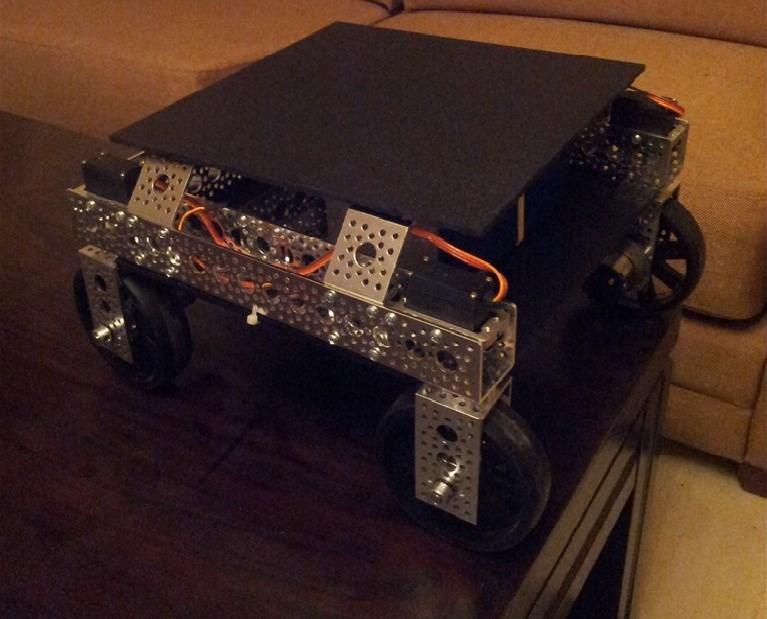
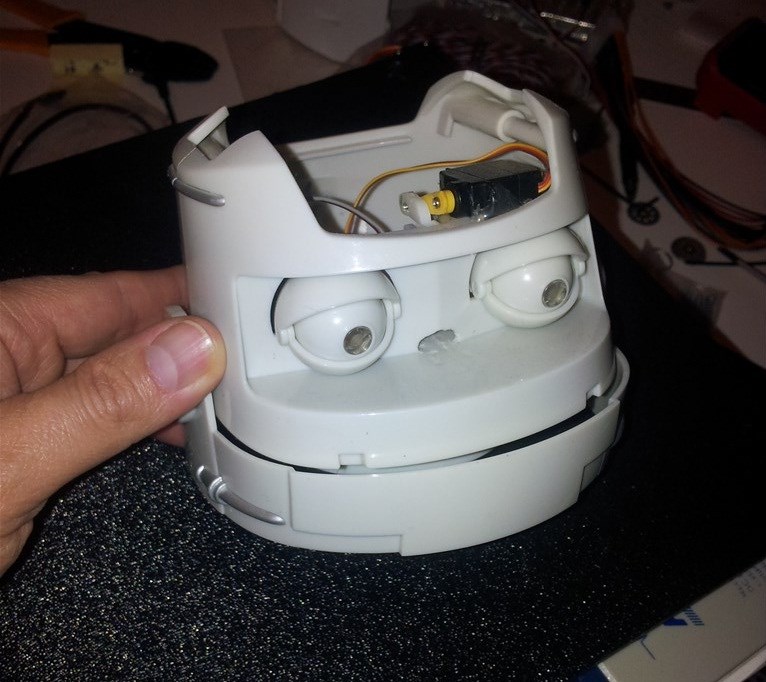
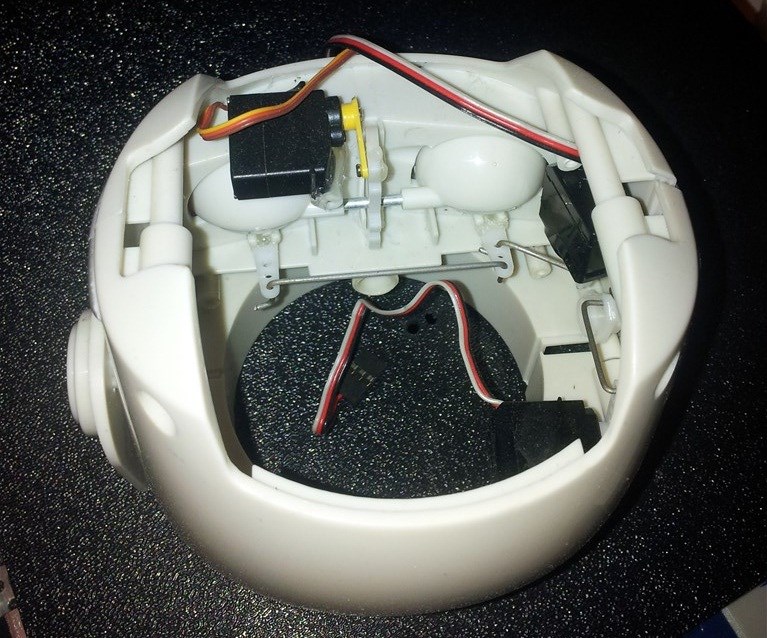
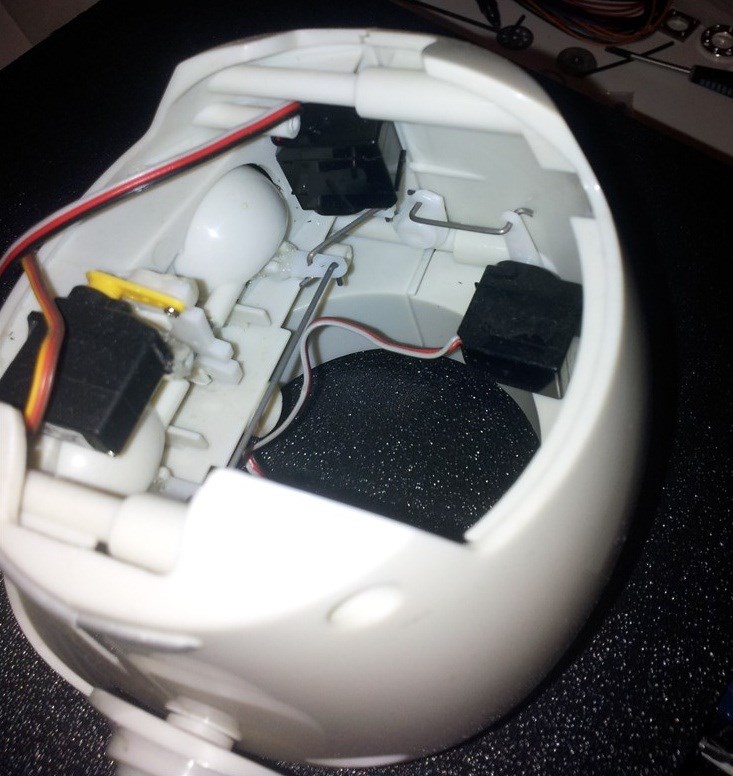
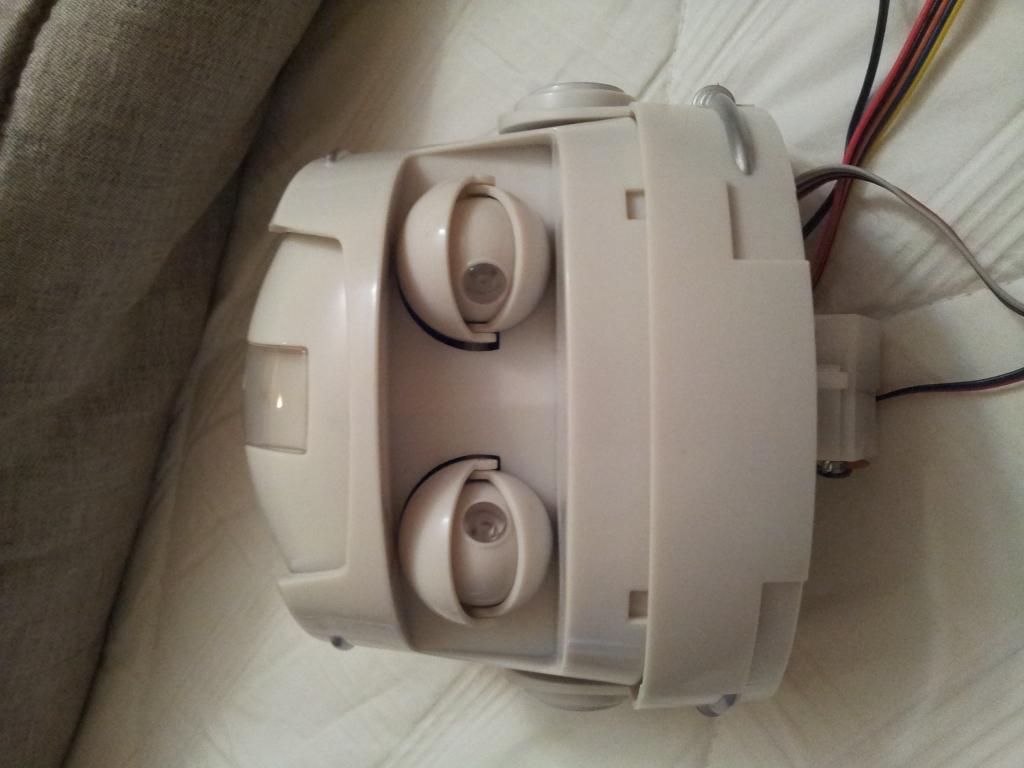
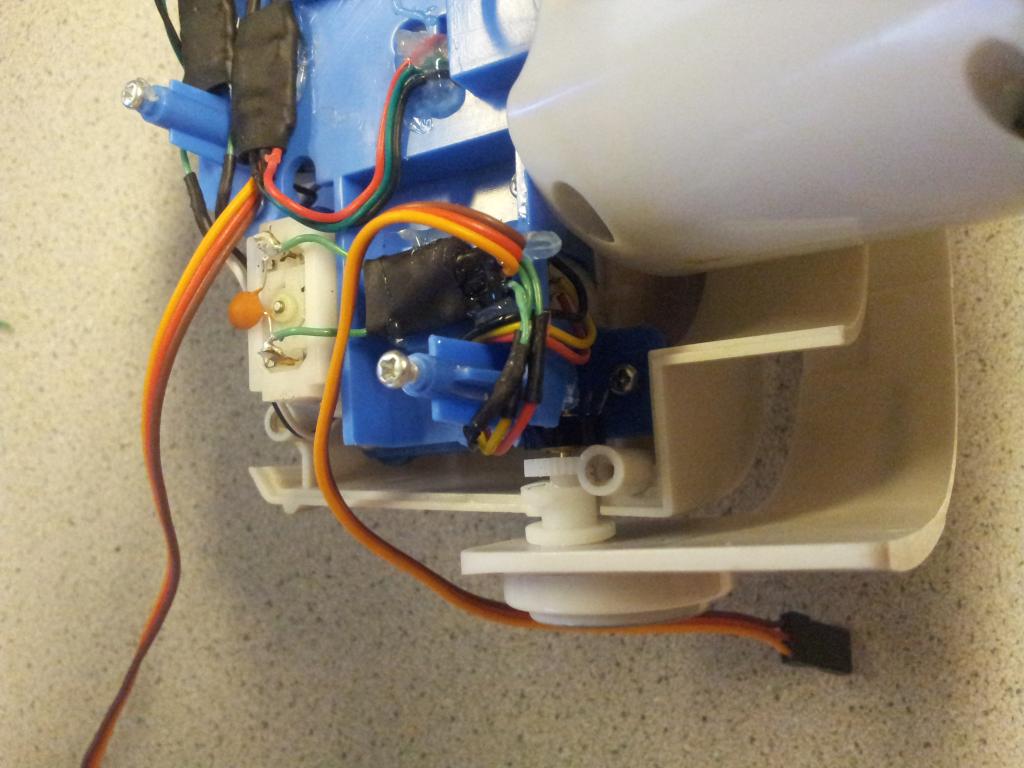
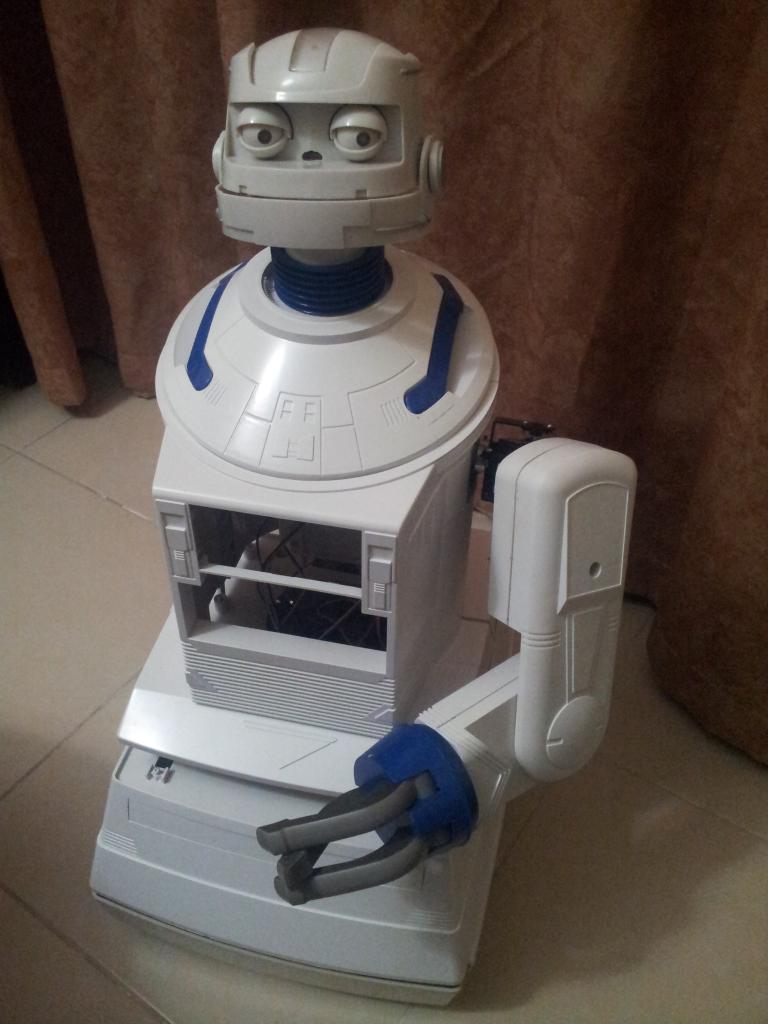
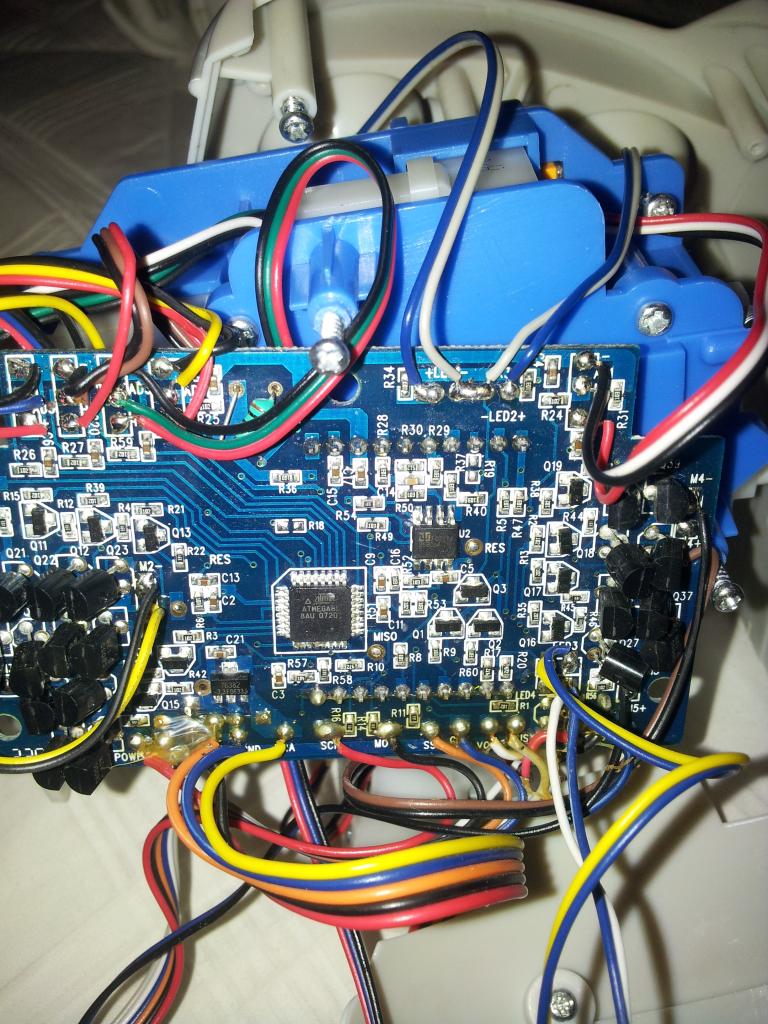
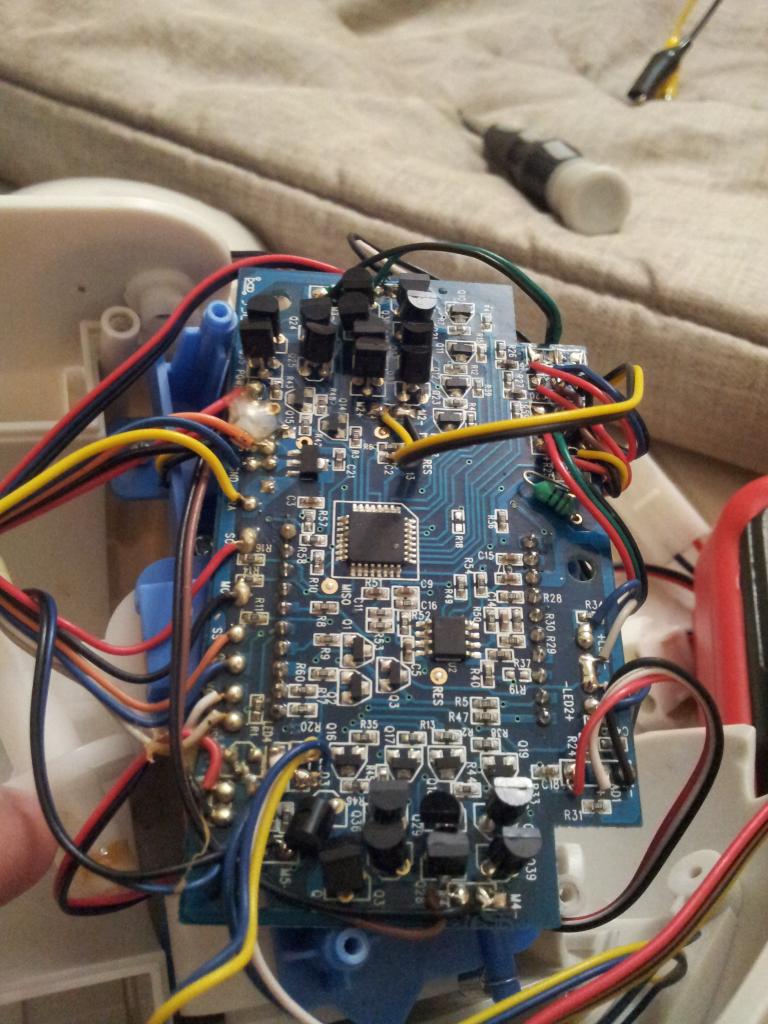
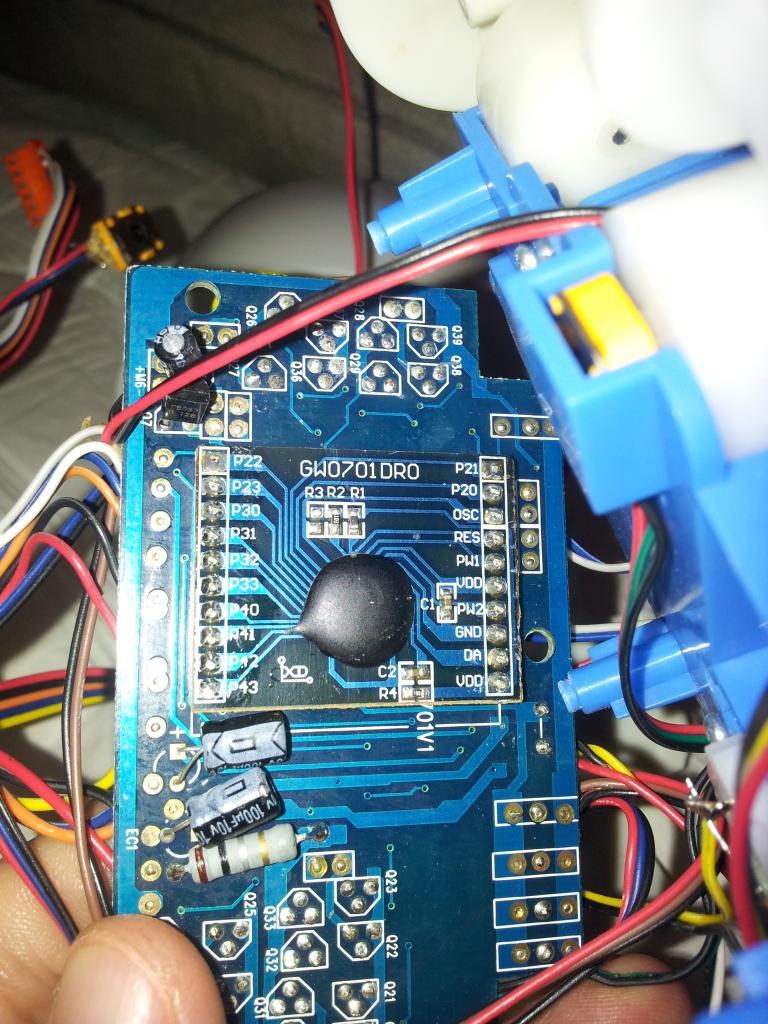
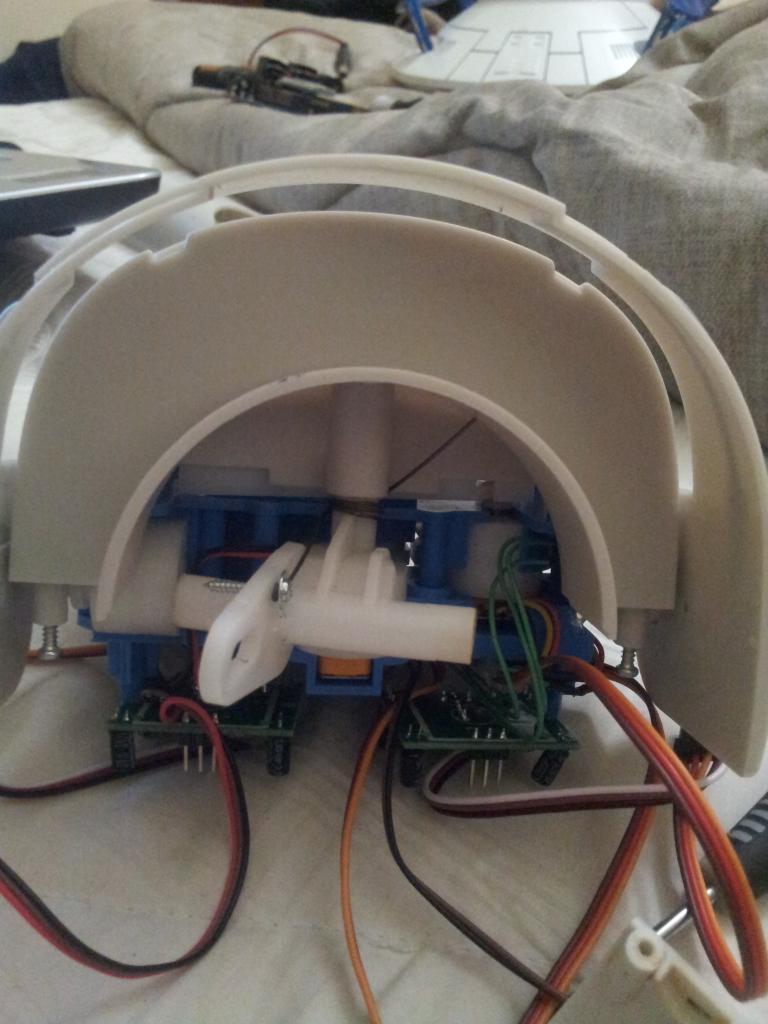
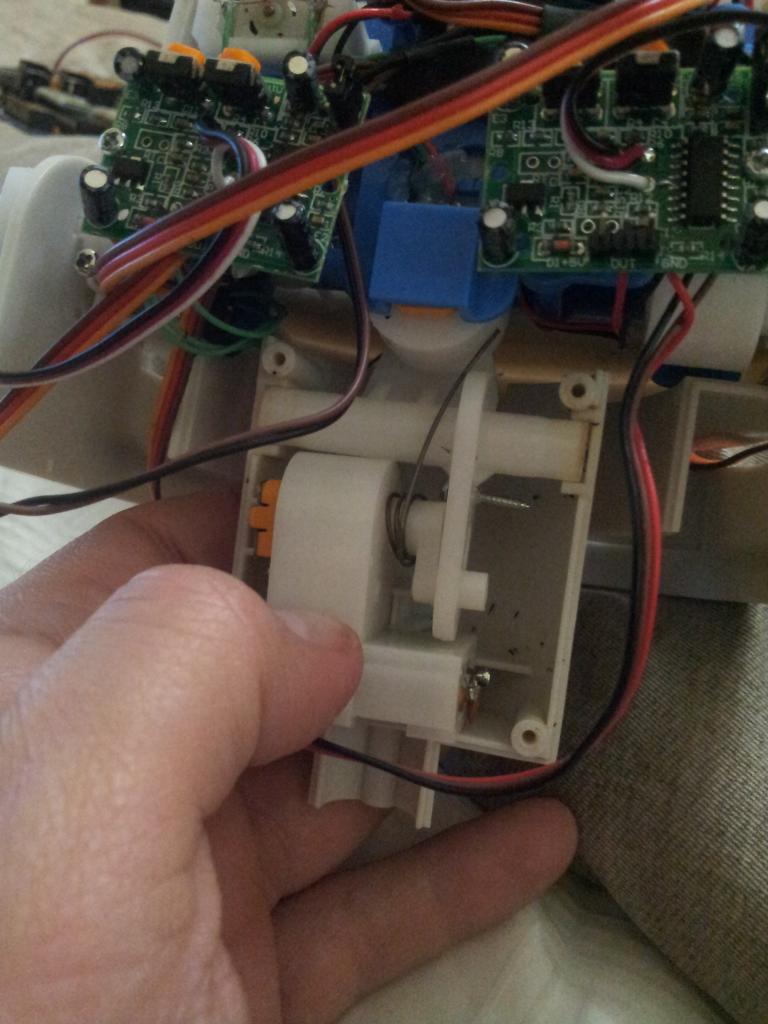
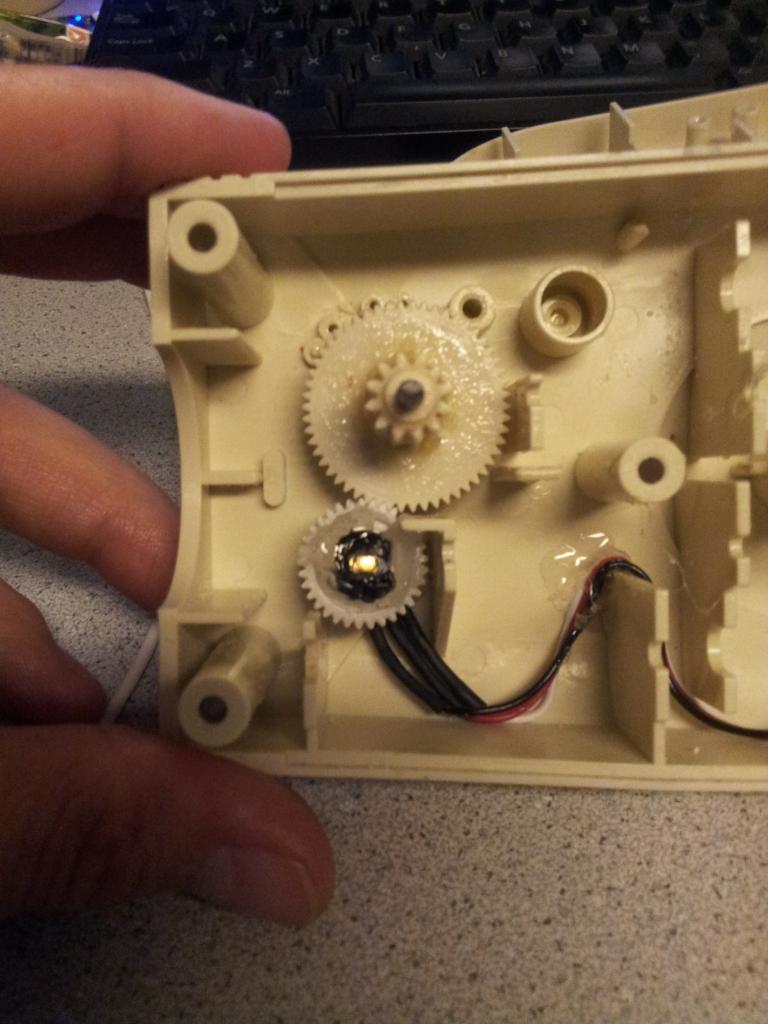
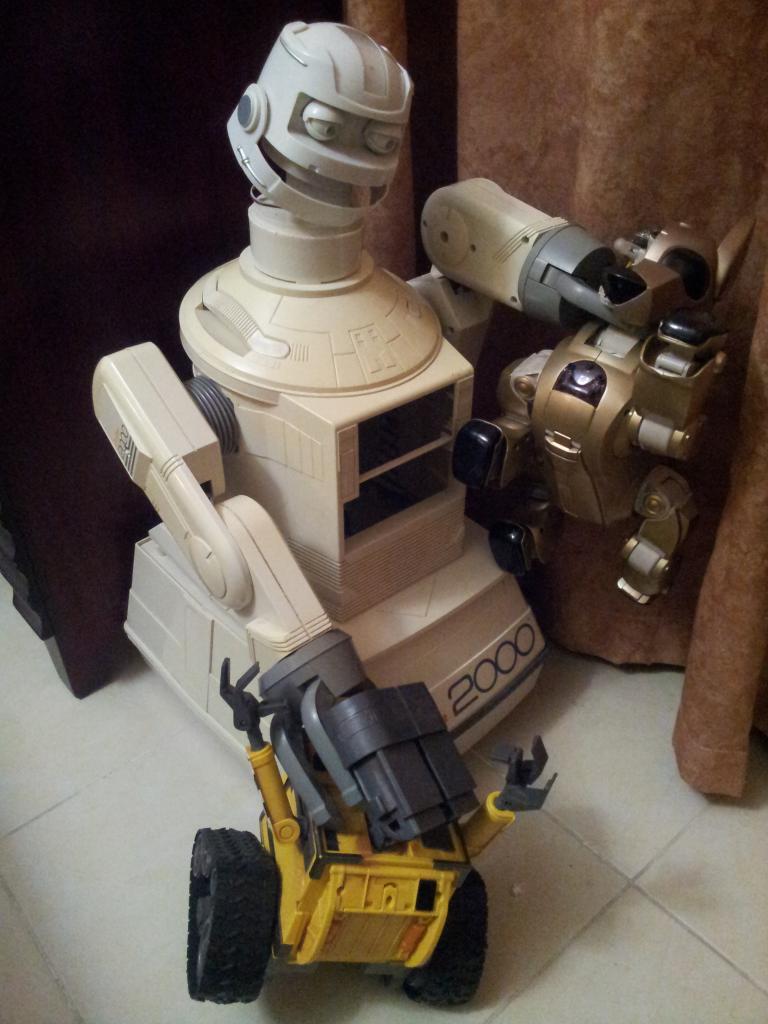
It's just a concept right now but I wanted others to see that the scale doesnt quite match. Right now its just stacked on there and neck is a little too long.
By Troy
— Last update
Discover more robots
Gabbott's Quadruped Called Thumper
Quadruped robot nearing completion: installing servos for head motion and refining gait to improve walking performance.
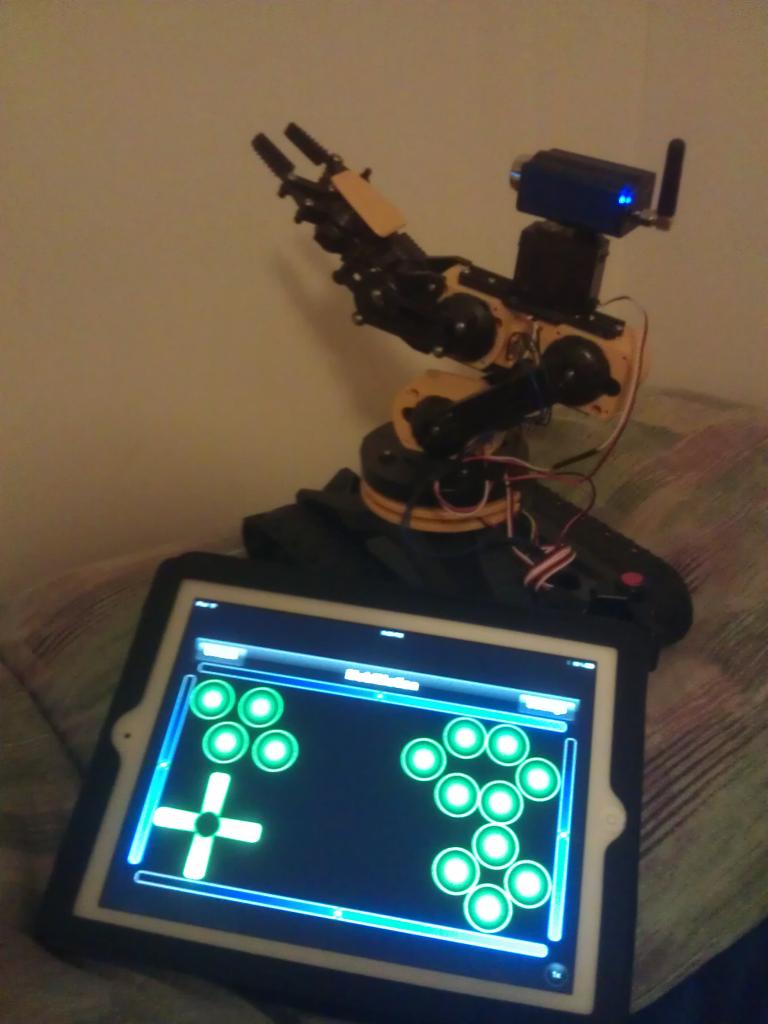
J's Robo Arm
Control a second robot arm from an iPad with the MobiMotion app-drive via accelerometer or joystick; photos show the...
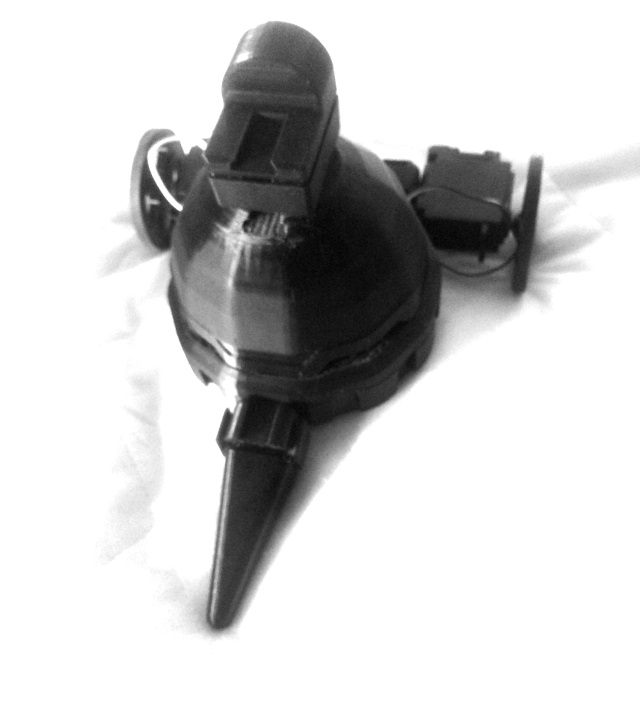
Itsmeintorre's 3D Printed Adventurebot
3D-printed AdventureBot built from 'bare' STL files with Ender3, EZBv4, 360deg servos, custom inner-tube treads; PLA...

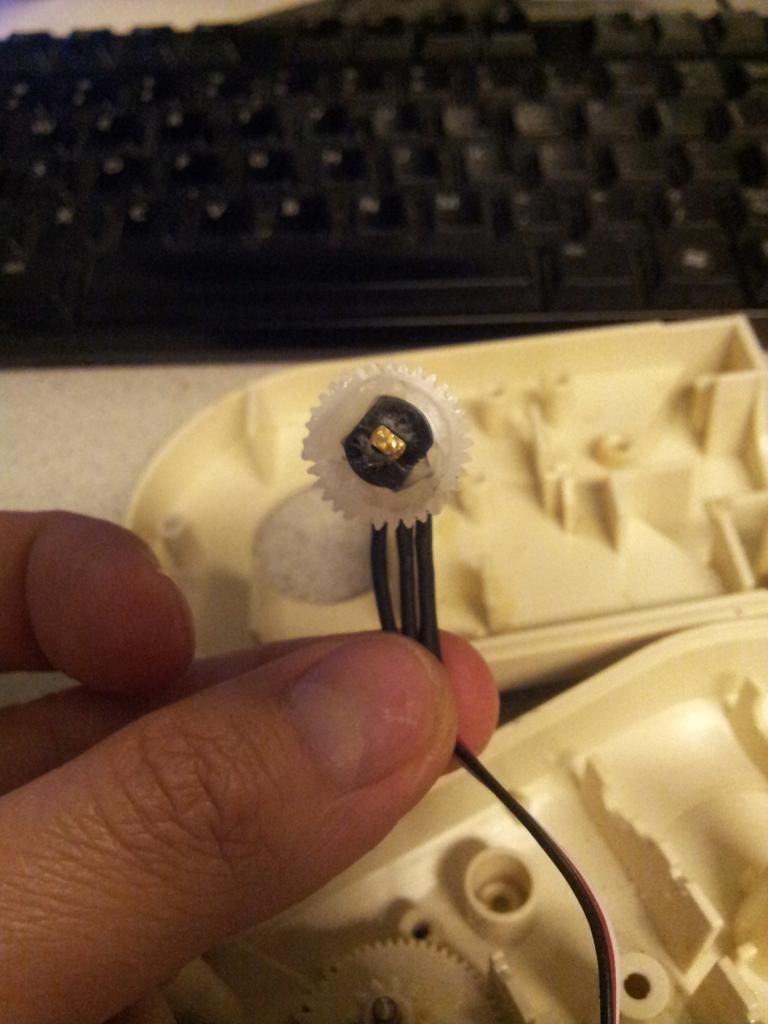
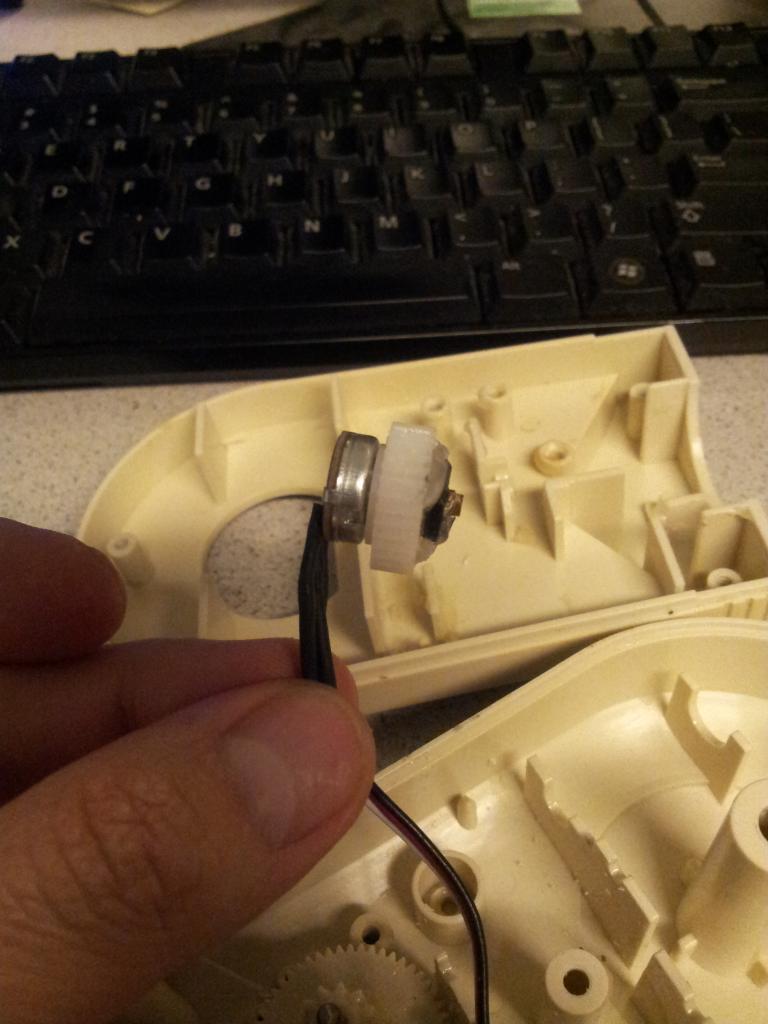
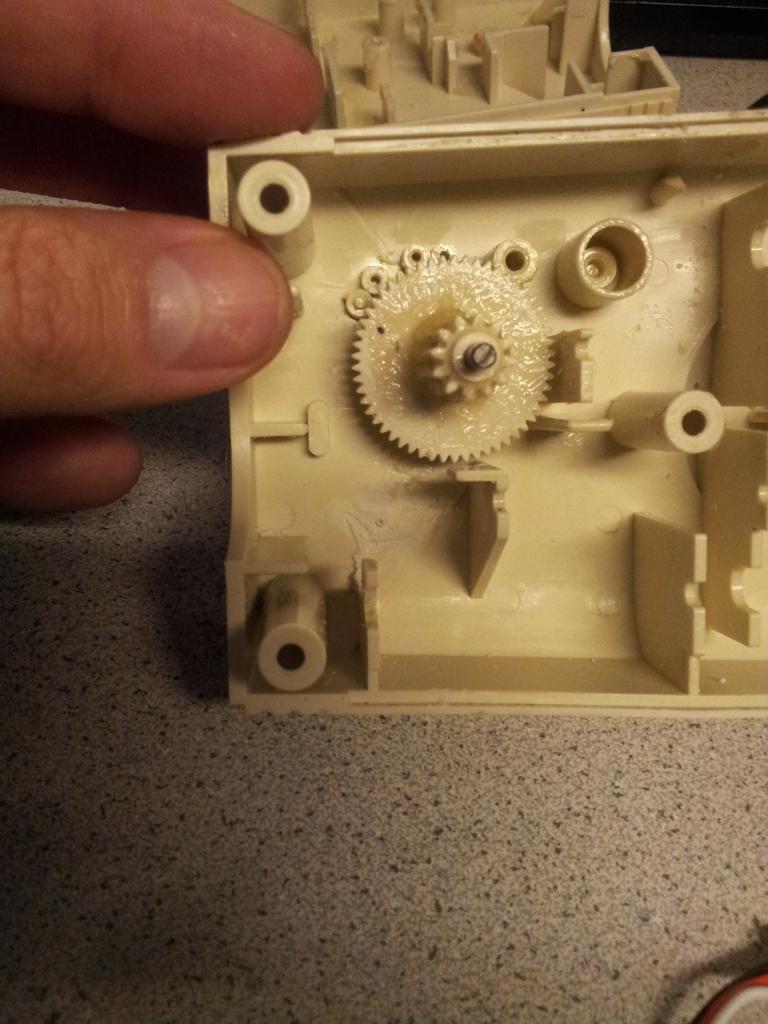
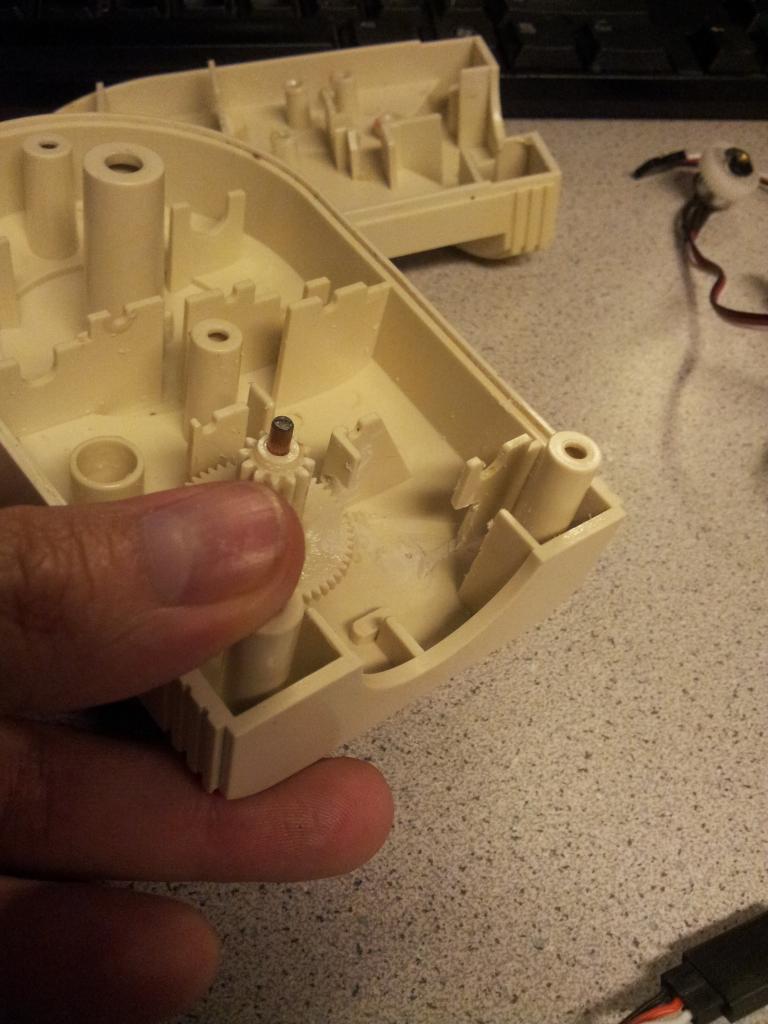
It looks like the easiest solution for now is to try and get original motors and gears for the claw. Anyone here not using original setup? Id buy them.
I have some dc motors from robosapien. Think you could use those?
Samantha
These are what power his legs, then I also have whatever is in his arms and waist.
Thanks Sam but I actually need the gears more. Josh and I are researching DC replacement motors. I found these and ordered them to test out. They can operate up to 12v normal and down to 4.5v.
Ebay link
Hey Bret.talent, can I get 4" of that blue duct?
Sure, just email me your shipping info. [email protected]
sa-280 not a bad motor ,but RS-380 has more torque and a very common motor in robotics
@Bret. Thanks! I really appreciate it. Let me know if I can help you out too.
@robotmaker, True. Those are good but the issue was trying to get them to fix in the arm's original motor mount area. RS-380 is longer and larger diameter and wouldnt fit there. Even the RC-280 isnt a perfect fit but I think it may be workable. Idk yet until it comes in. The proof in the pudding will be if the axle sits correctly for the gears to mesh. I figure anything is better than what's in there now.I will let all know after I test it.