This is a test, hard to balance Mr. ConeHead dancing
Take 2 soon :-)
By EzAng
— Last update
Discover more robots
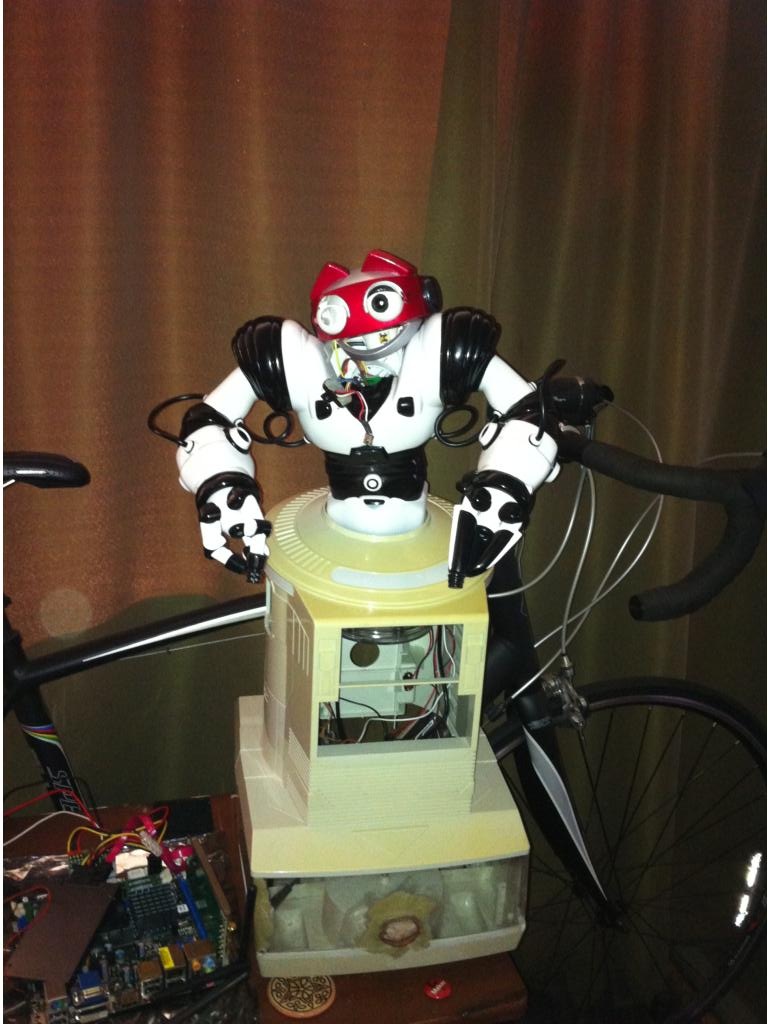
Sfoy's My Frankenbot - Robosapien, Hearoid, Ottobot Head
Build a custom hearoid omni bot base with mini-ITX, acrylic enclosure, IR sensors, cameras, pan/tilt, EZ-B integration...
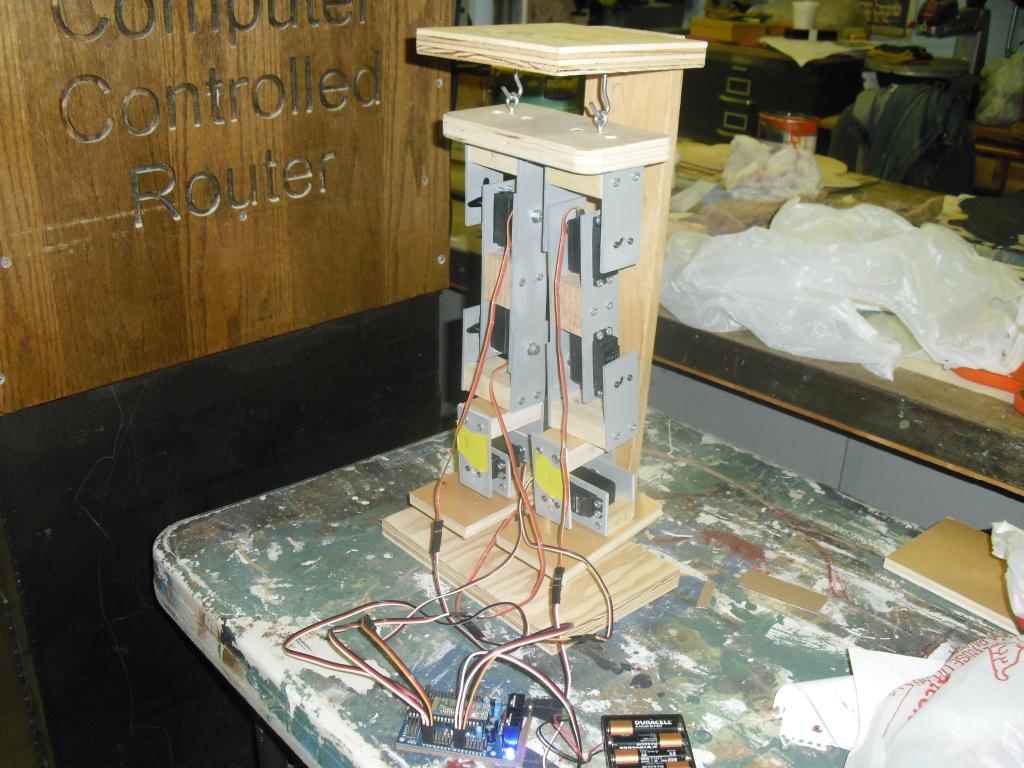
Jeffmorris's Homemade Biped Robot
Upgrade EZ-Robot hip servos that can't lift biped legs with higher-torque servo recommendations for reliable leg...
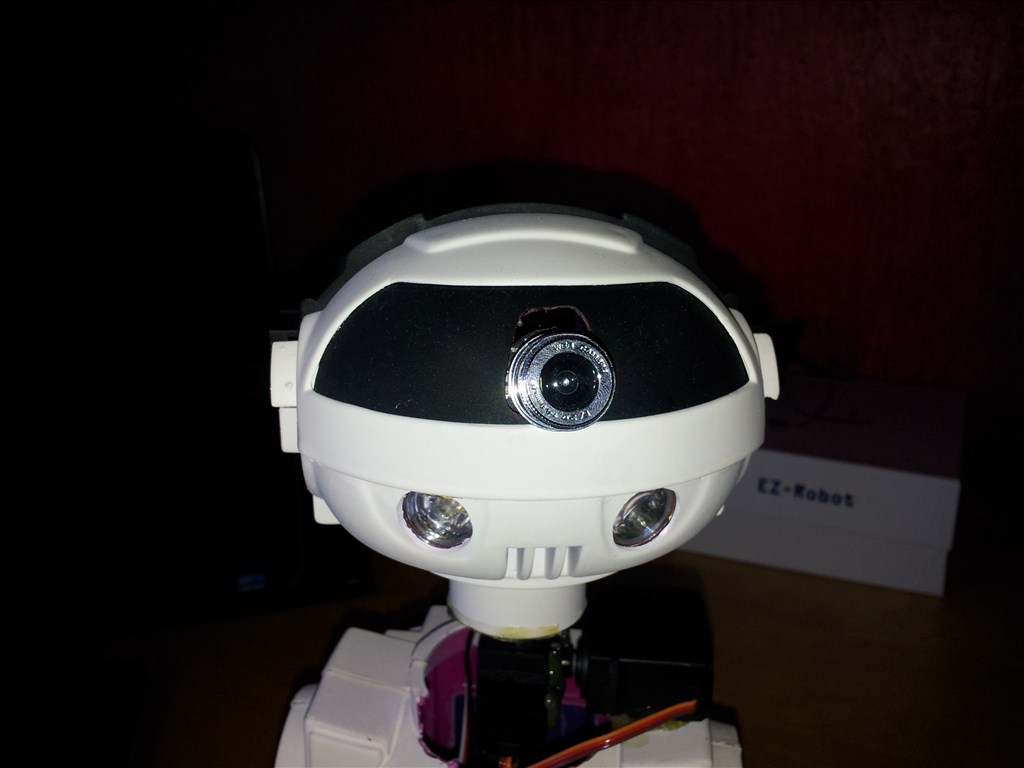
Hablijack's Project: Marvin
DIY MARVIN robot: USB-powered camera, moving head, OWI-arm hand with servo; arms next, feet TBD.

These experiments bring a smile to my face! Freestyle robotics is where it's at
If you truly want to get some bipedal walking motion happening you need an ankle joint, but I'm guessing you've already arrived at that conclusion
Yes, which servos for that?
look at your jd robot.foot D17/18 and D13/14
Thanks Nomad! I was going to suggest the same thing:
https://synthiam.com/Shop/AccessoriesDetails.aspx?prevCat=104&productNumber=1210 https://synthiam.com/Shop/AccessoriesDetails.aspx?prevCat=104&productNumber=1211
You might be able to get away with a DIY solution but the JD ankle/feet gives you the general concept.
ok I will look at that, thanks