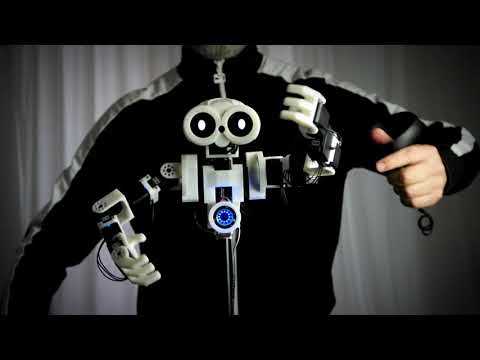
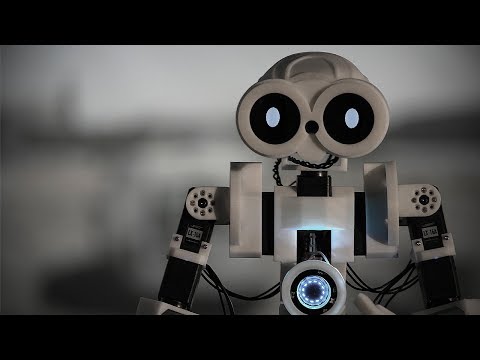
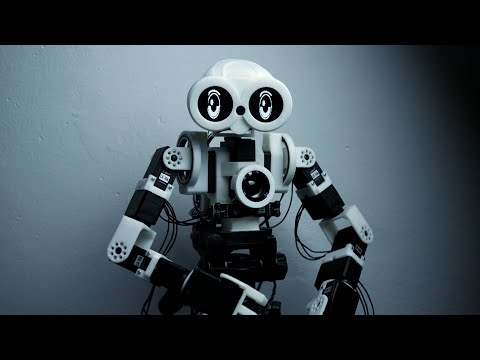
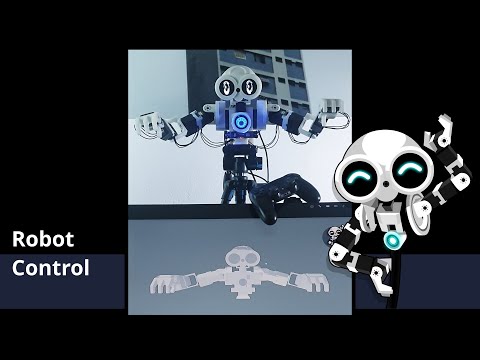
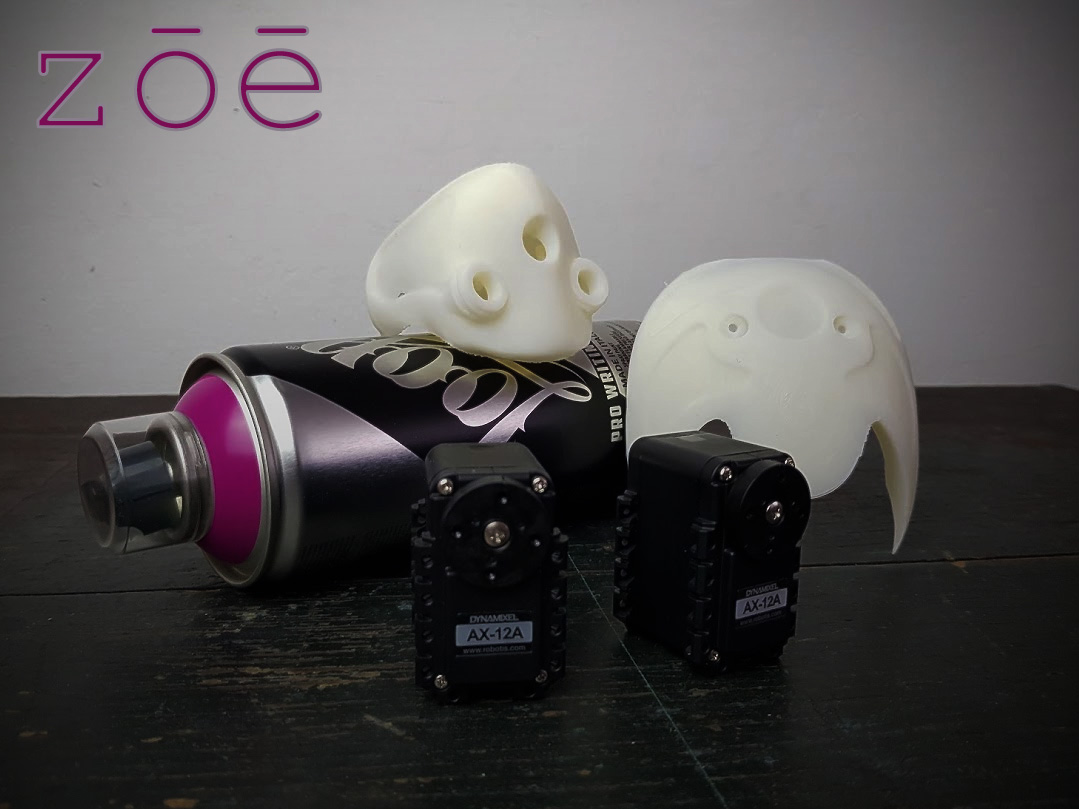
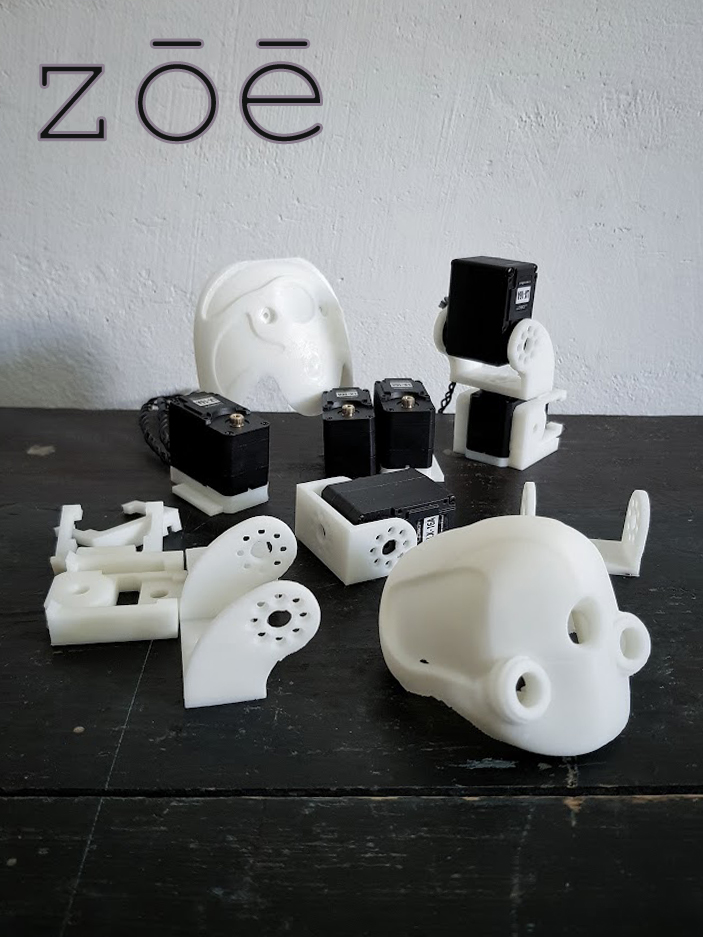
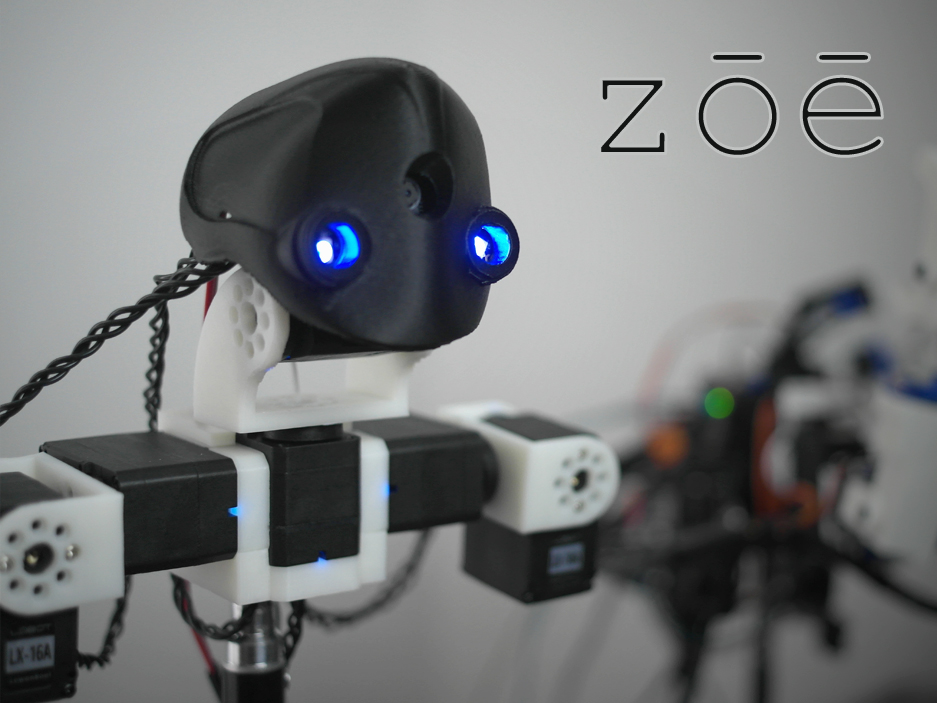
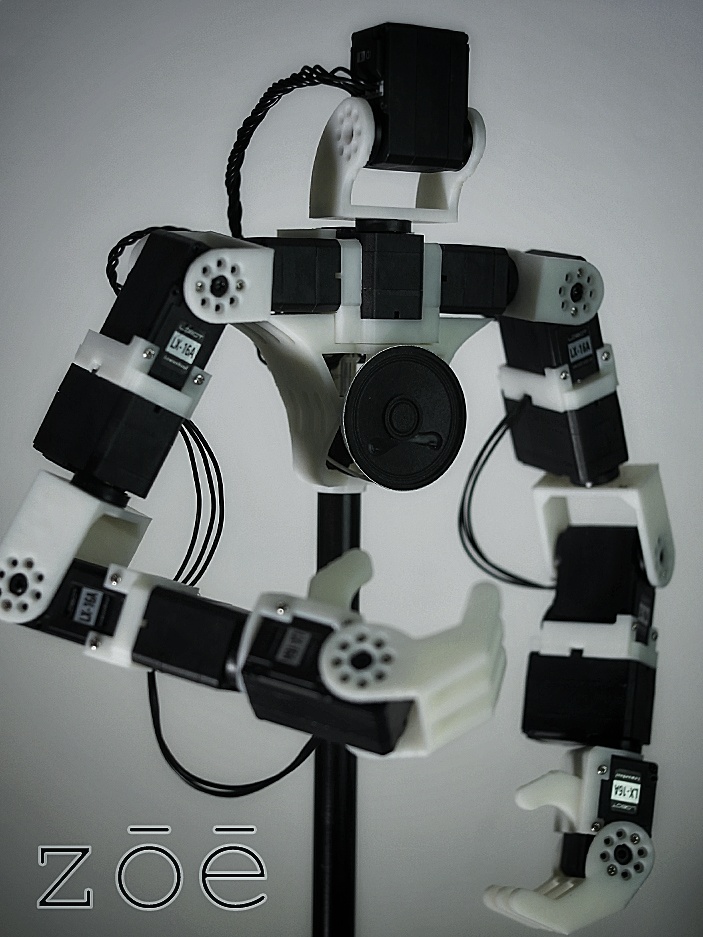
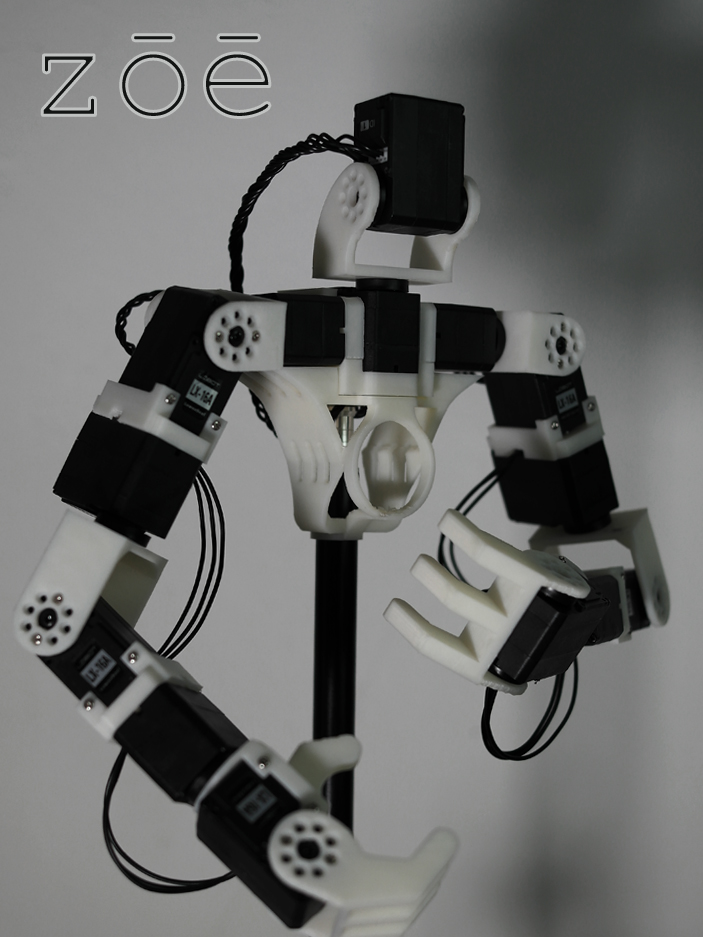
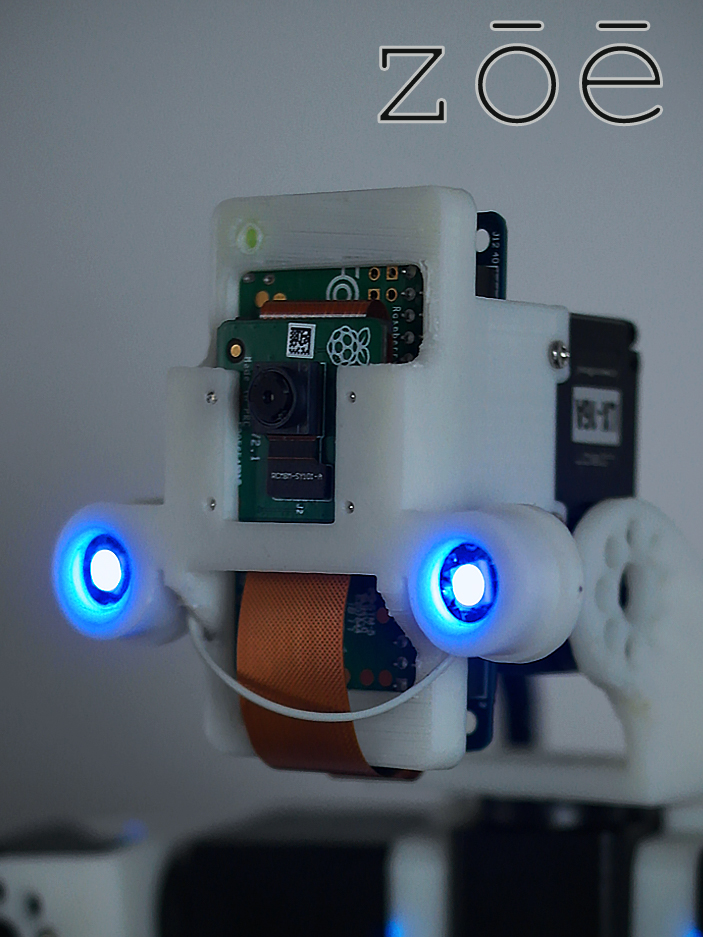
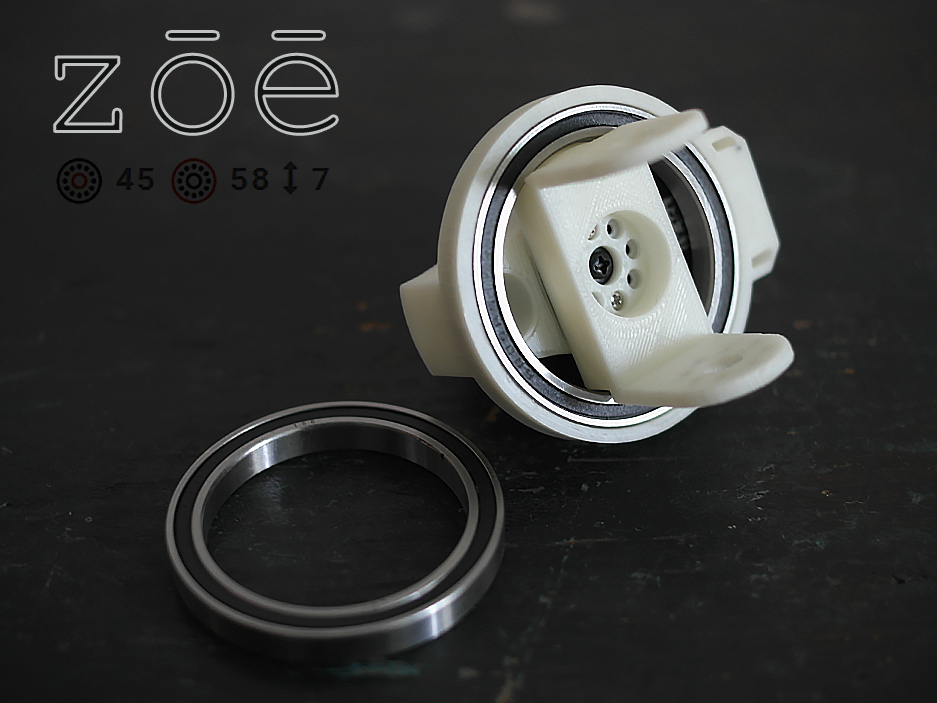
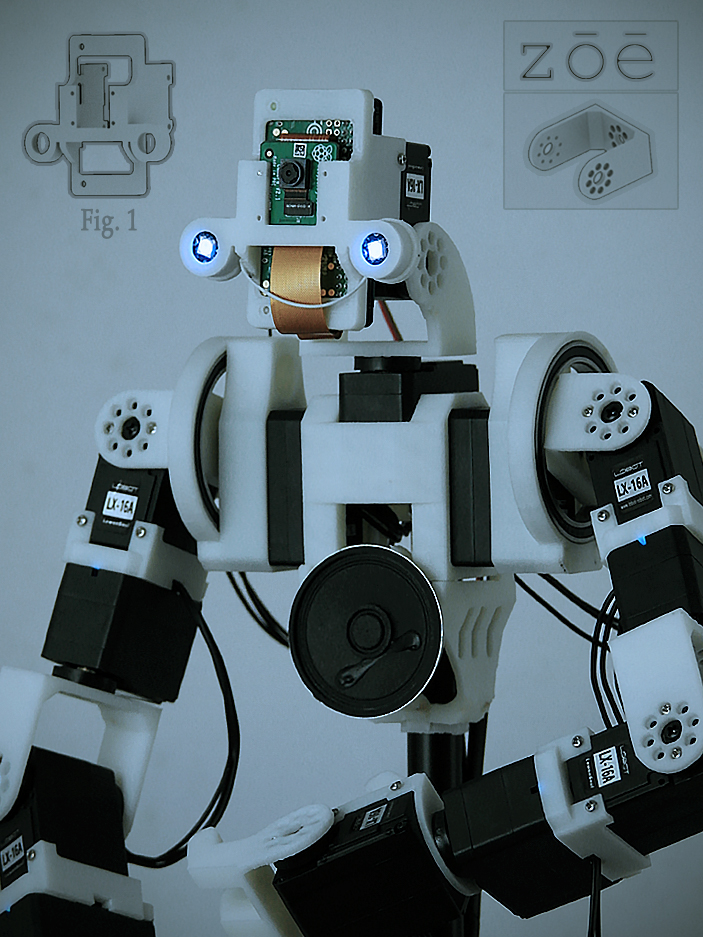
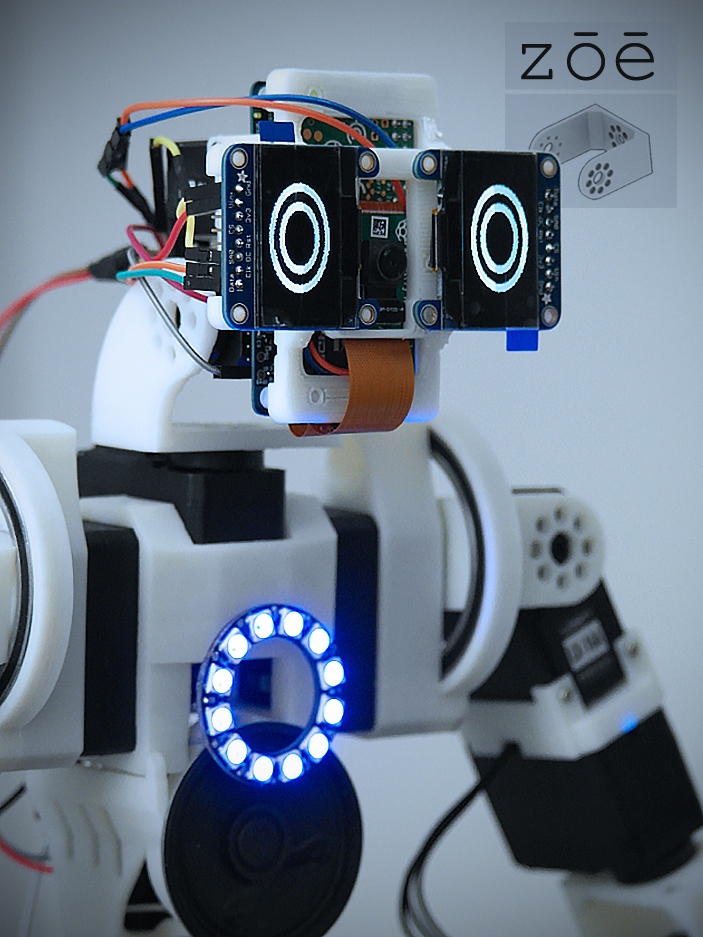
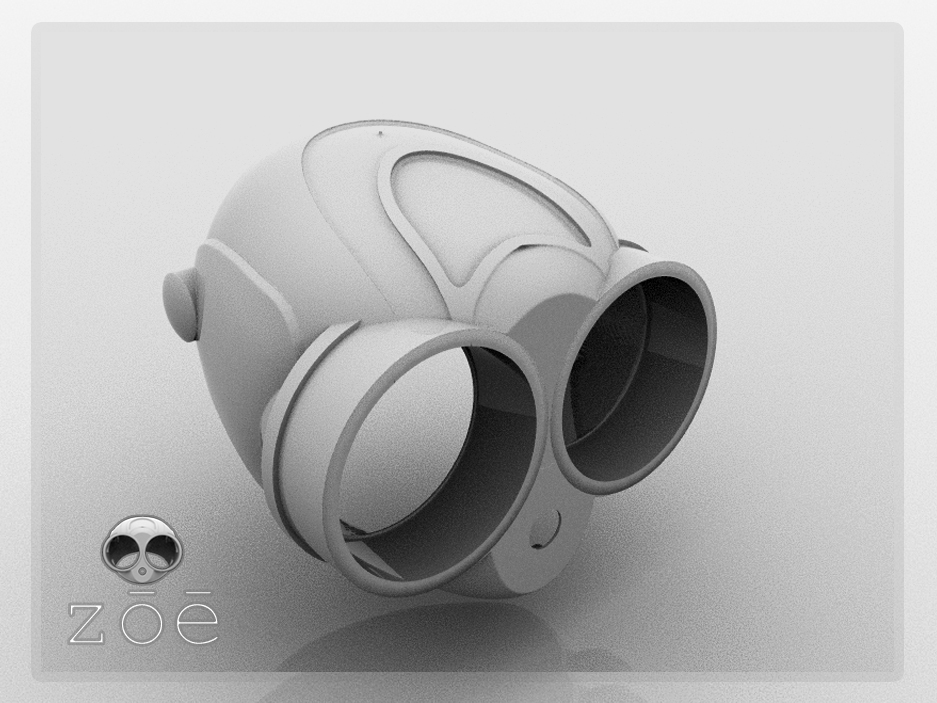
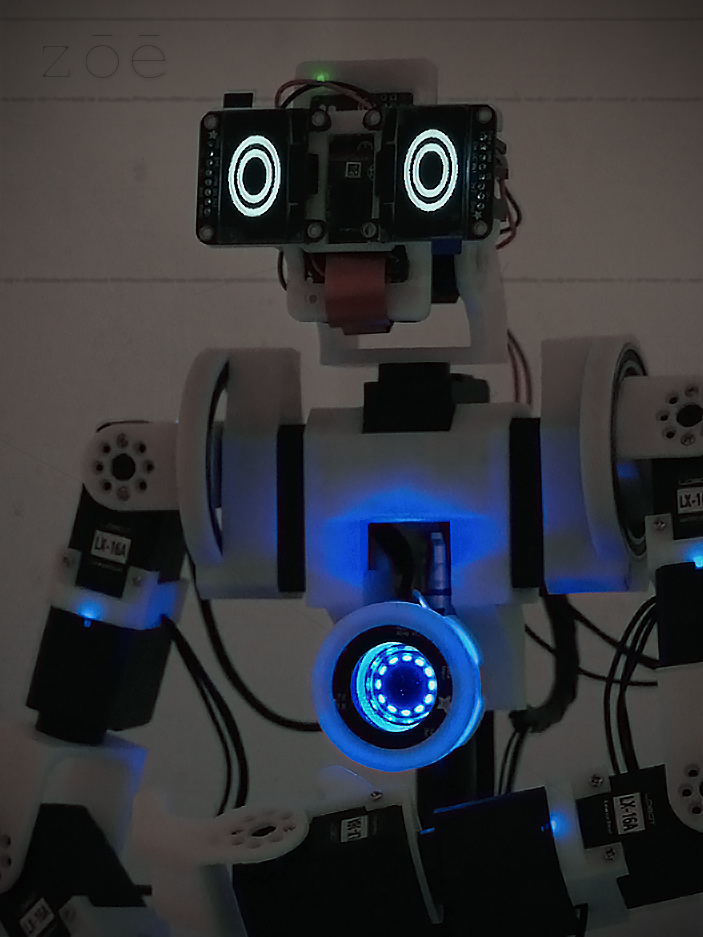
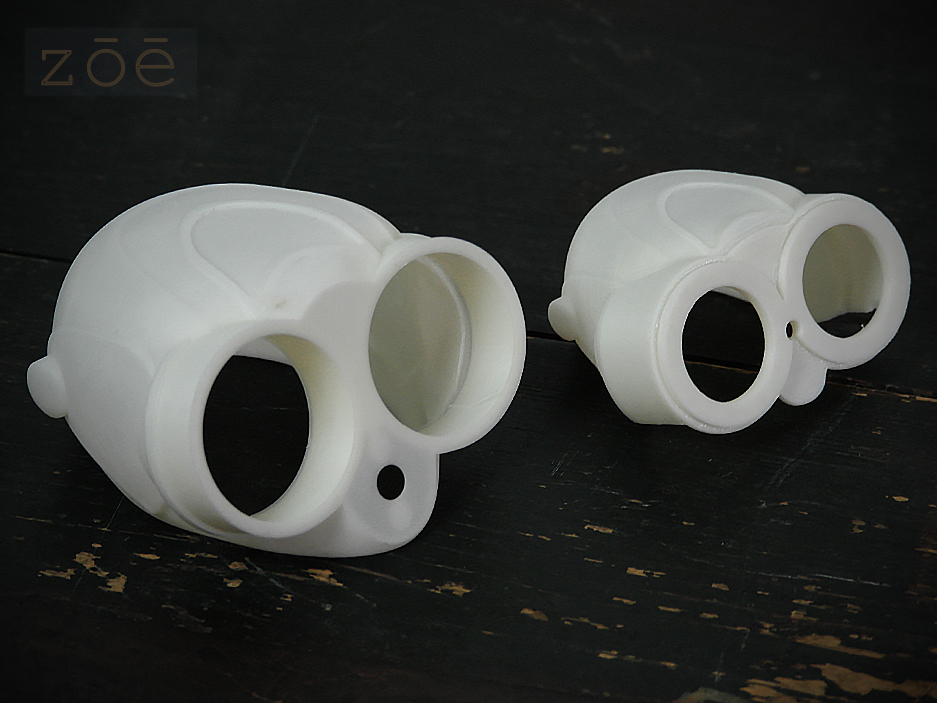
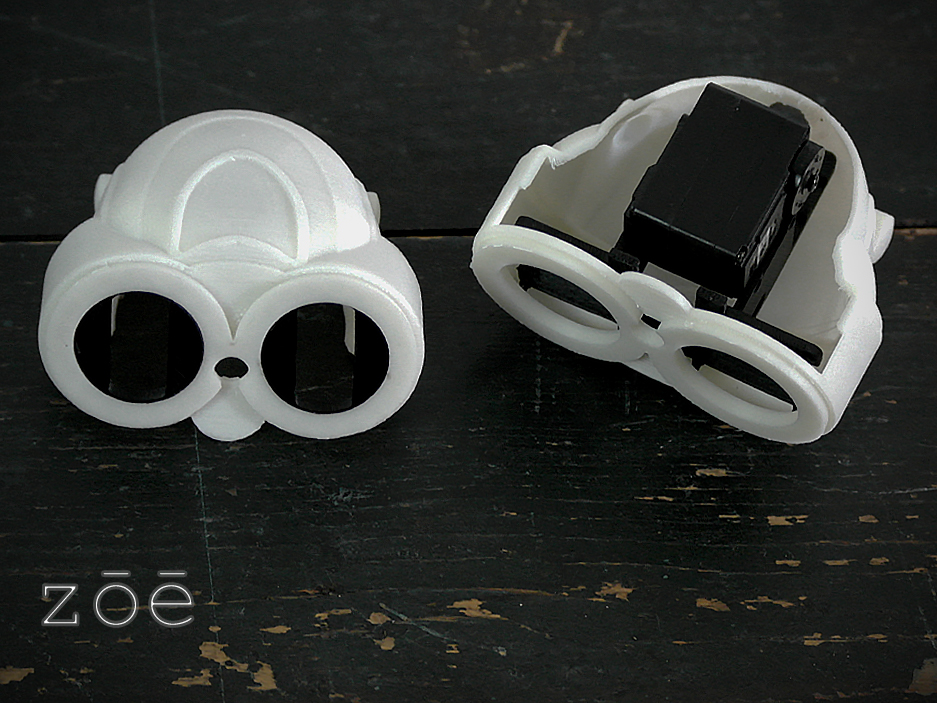
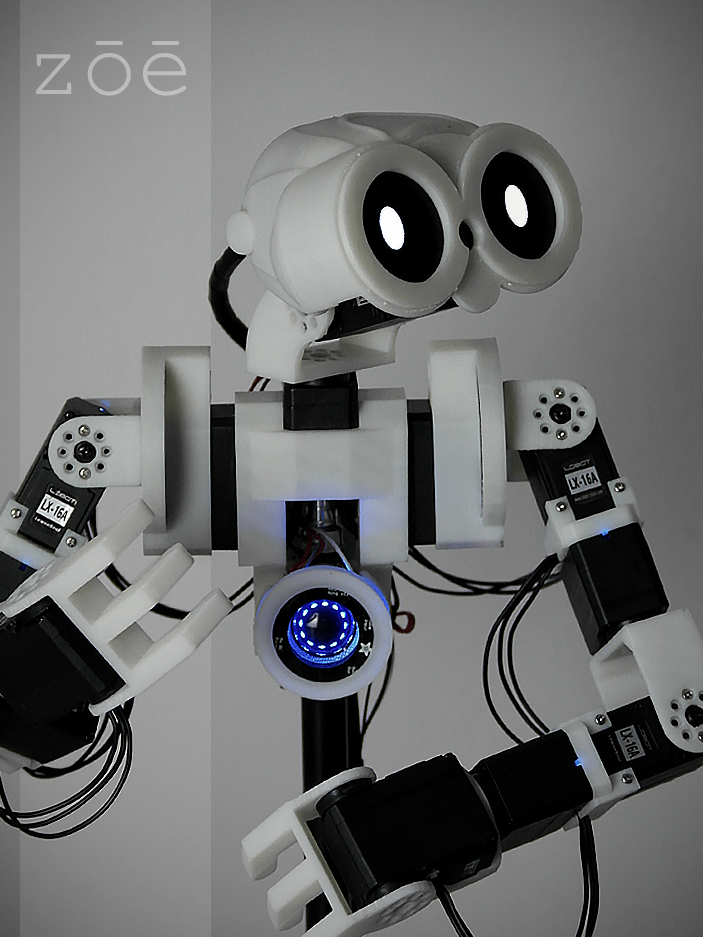
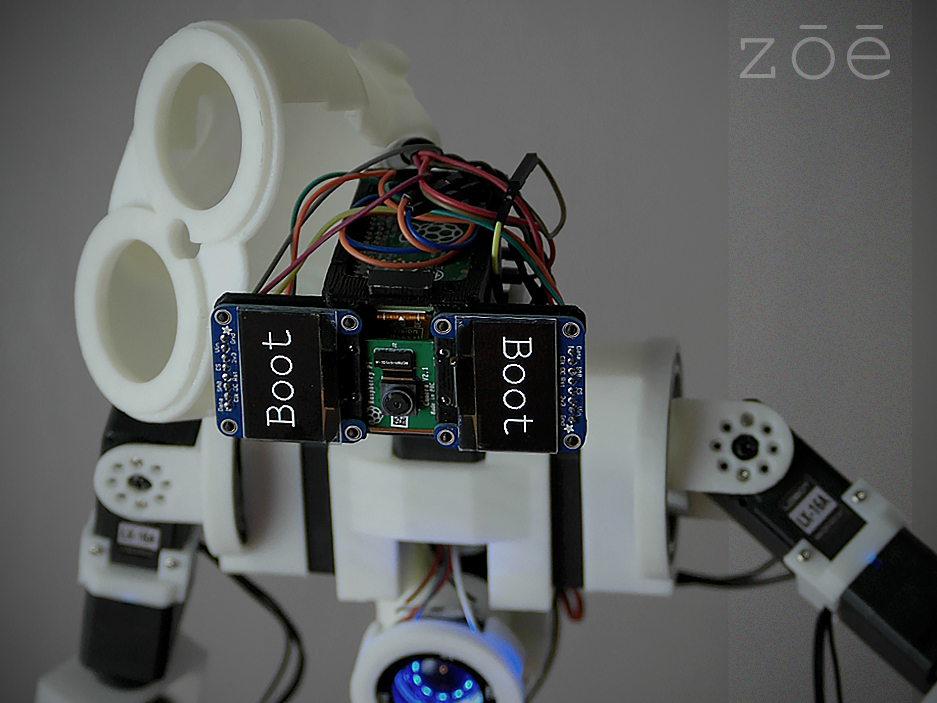
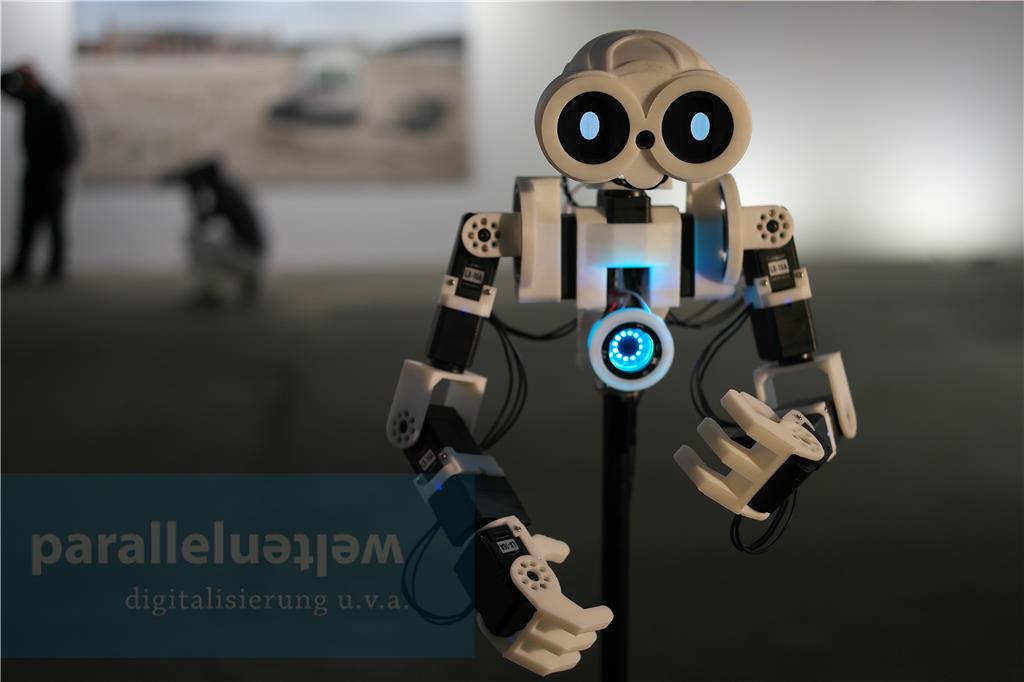
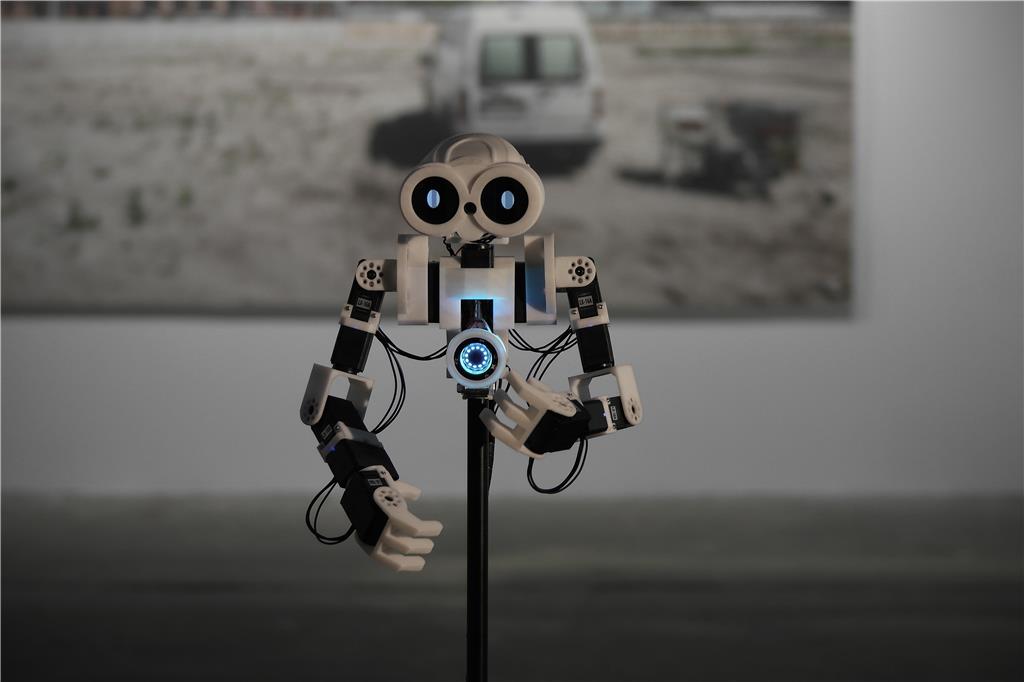
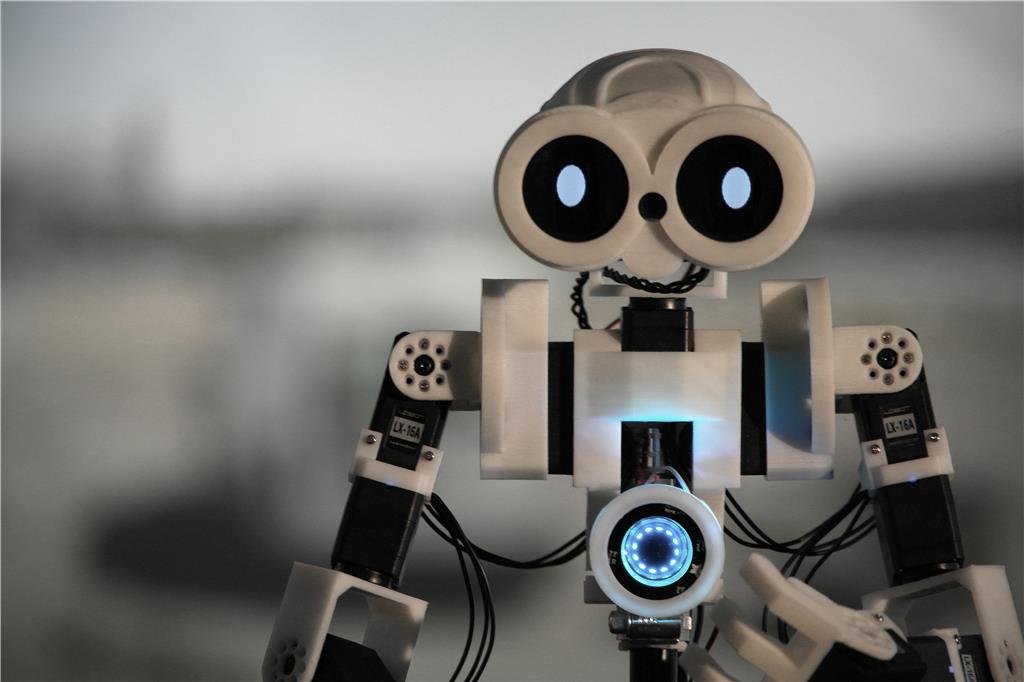
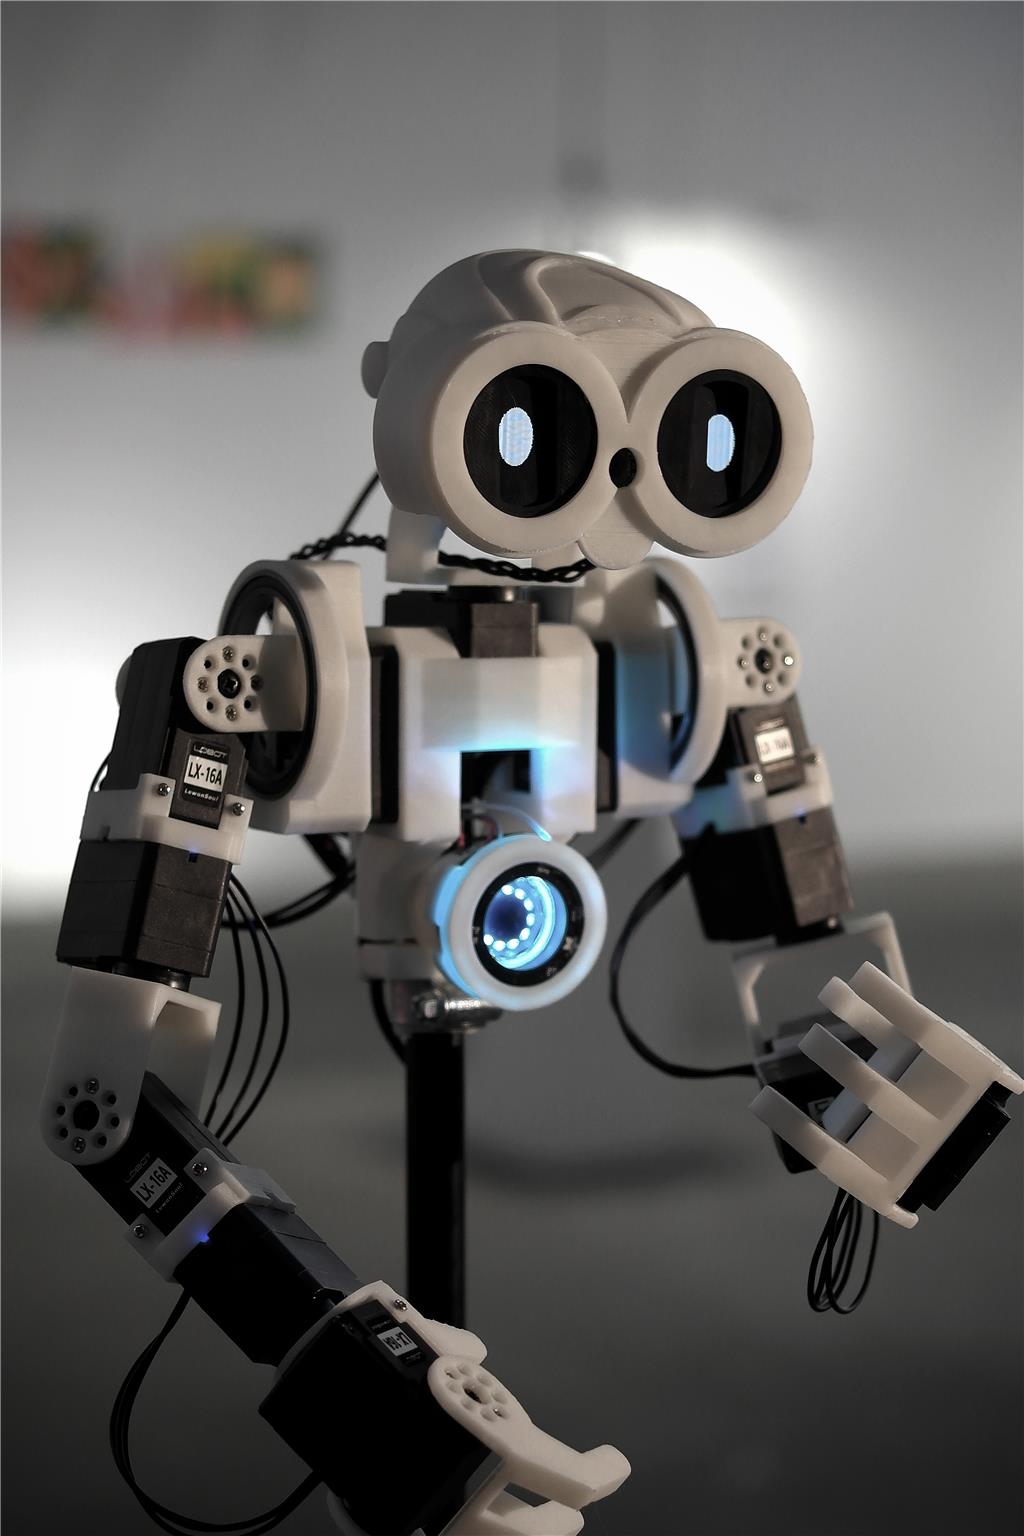
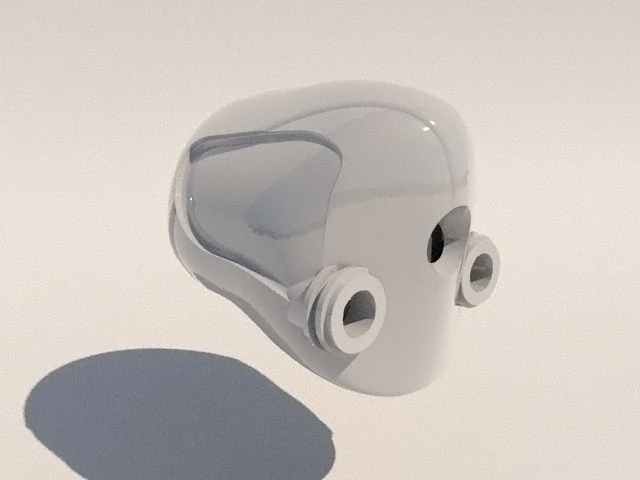
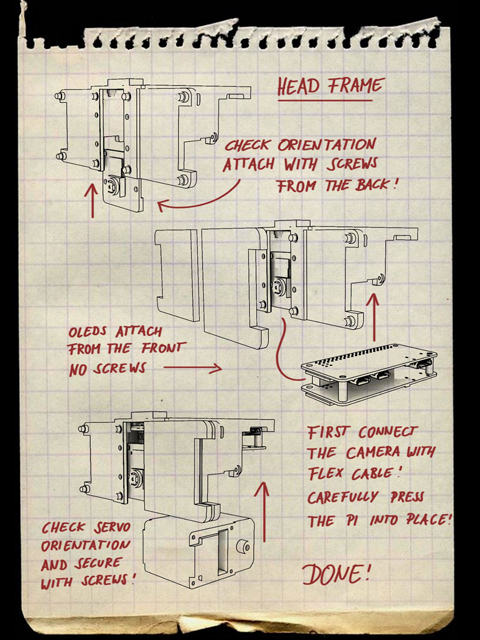
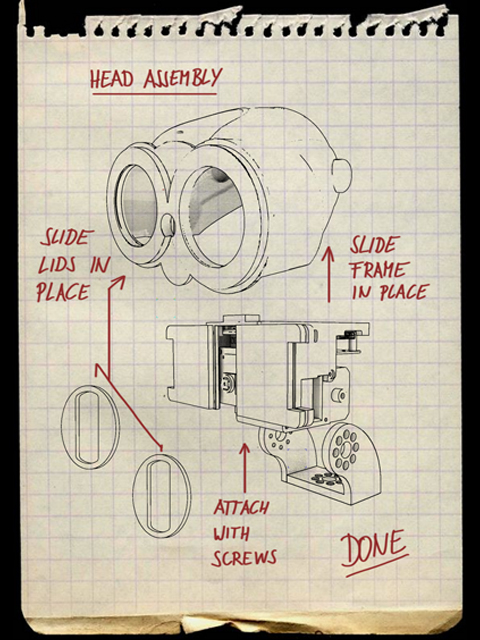
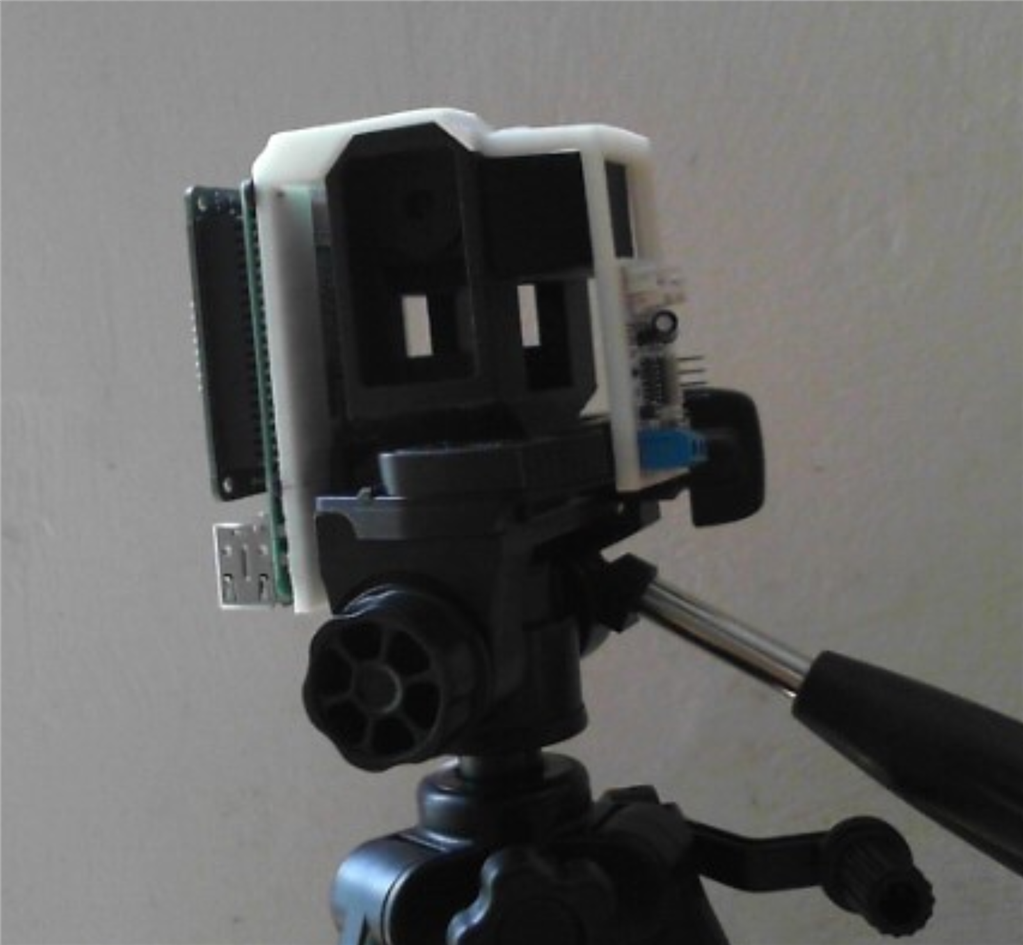
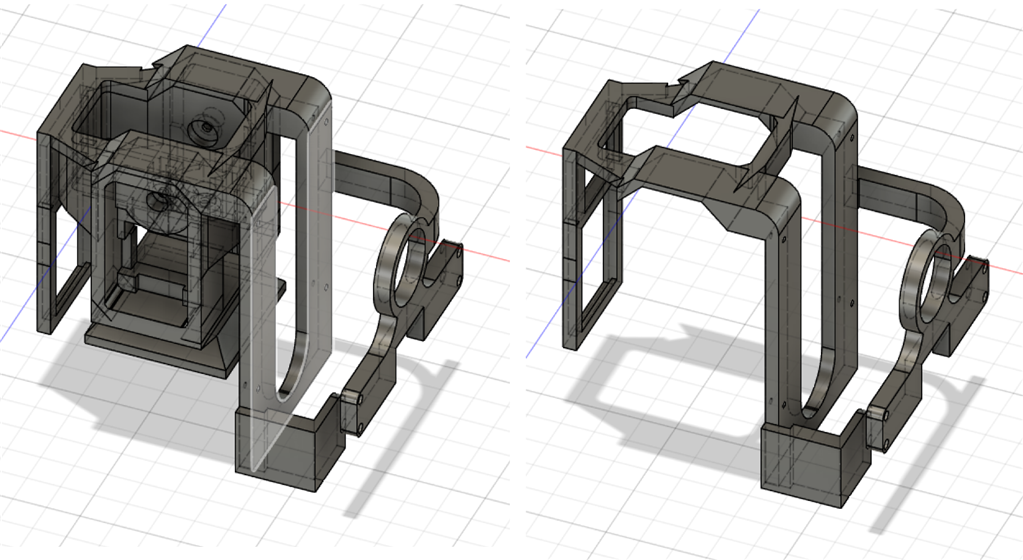
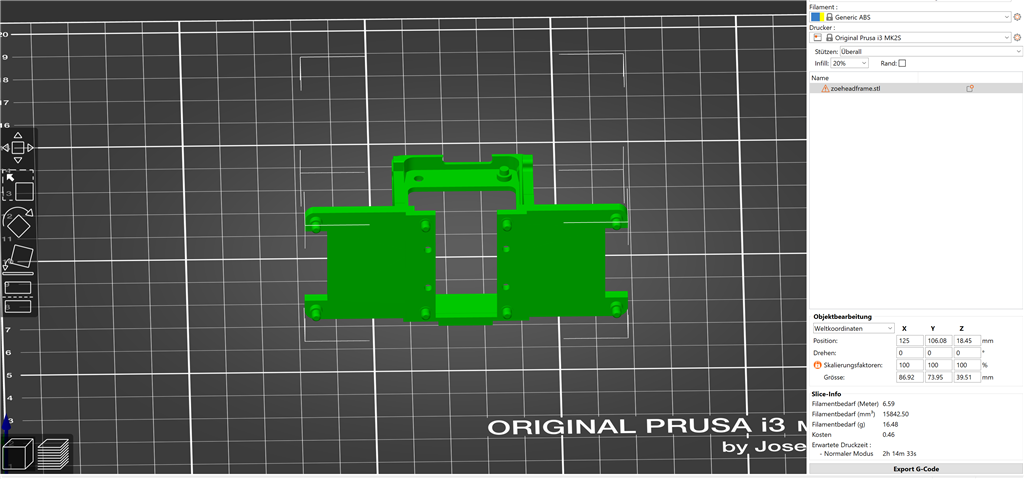
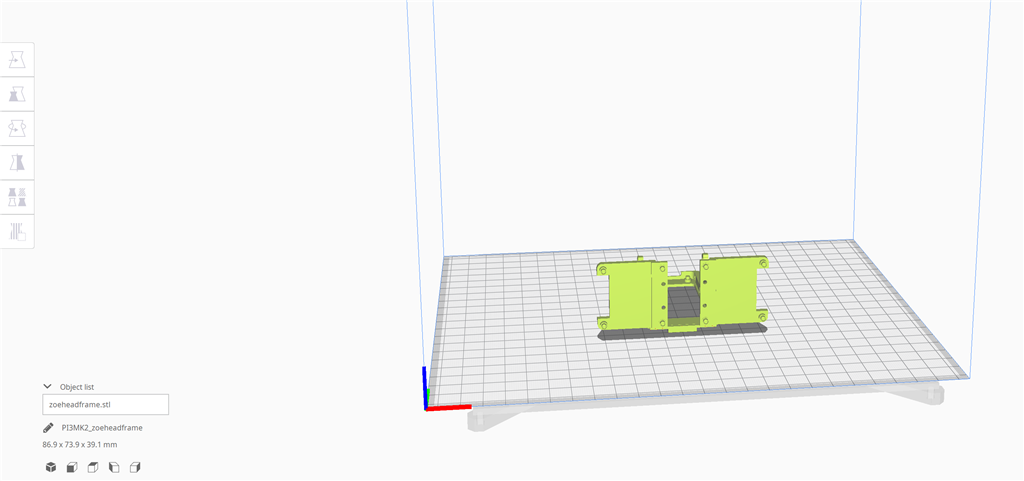
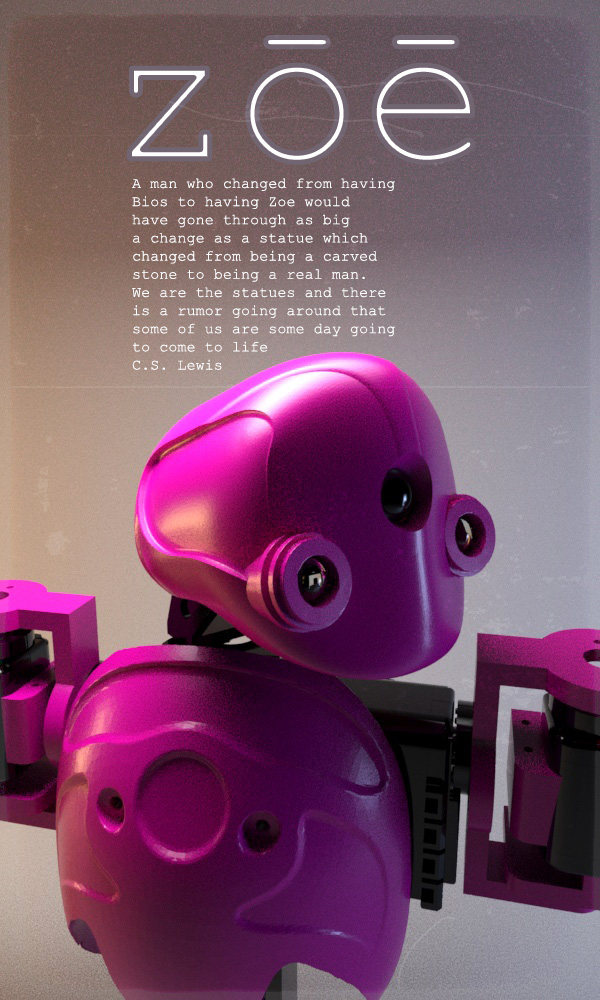
Since my robot is running on a Raspberry Pi, which is now supported by ARC, I decided to evolve my current project K[8] into a new one called ZOE... First steps will creating a new servo setup which supports Dynamixel Servos, and a new Conceptual design!!
By Mickey666Maus
— Last update
Discover more robots
Steve's Meet Aegis
AEGIS robot built from junkyard scrap: steel box-section chassis, drain-chamber torso, car window twist motor, truck air...
Rb550f's Meet Tk
TK robot - 31in tall, 12in base, 12lb with 12V battery; rotating torso/head, tilting dome, arms w/3 HD servos, digital...
Cliffordkoperski's HAL THE ROBOT THAT WALKS AND TALKS
5.5ft humanoid walks, talks-56 servos on 3 EZB v4 boards via WiFi, two batteries, onboard PC; Synthiam ARC scripting...

Noma d where are you?
come back and try it mickey
@EzAng.... Time zones EzAng, there are 24 of them... It is 2:13am in Germany at the time of this post.... Maybe they went to bed?
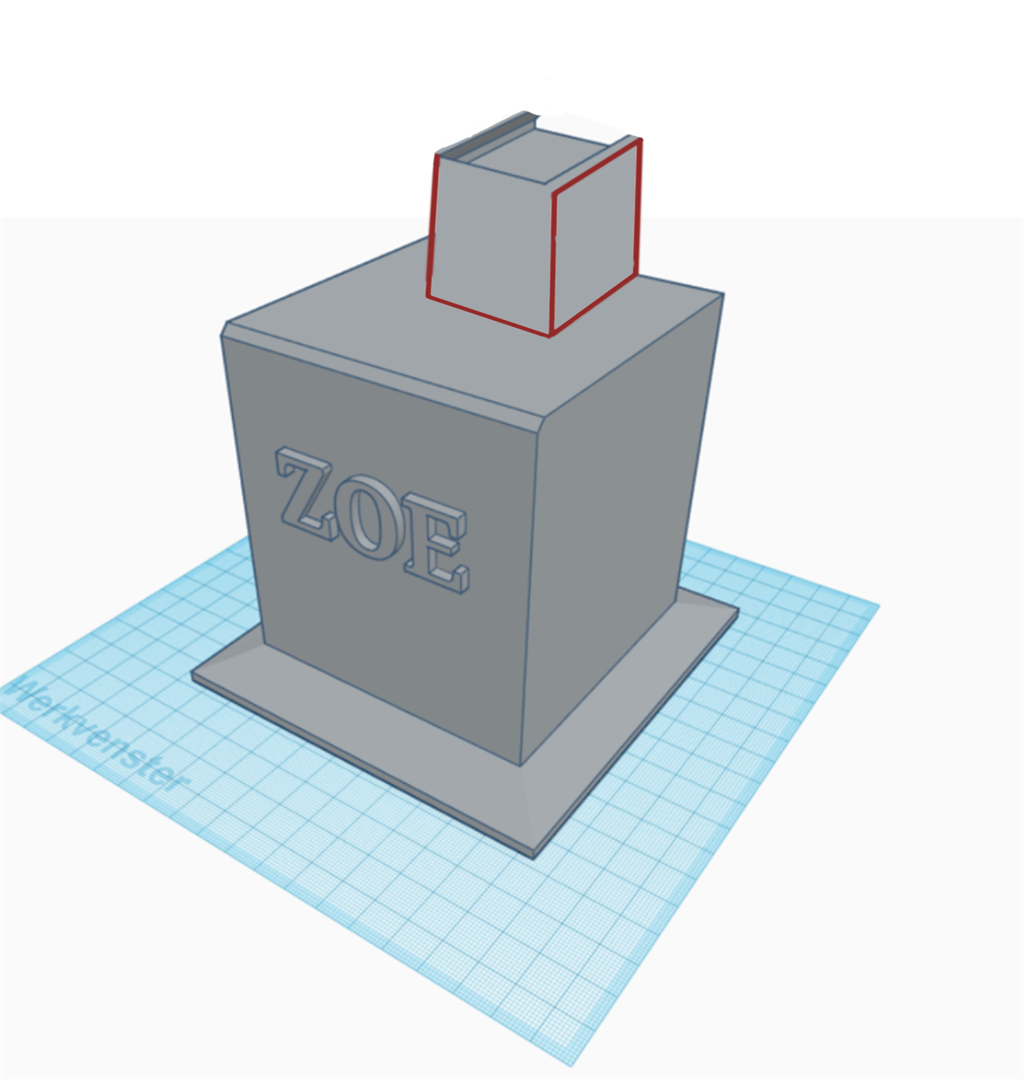
Hey Nomad, maybe you should modifiy the stand for ZOE a little bit befor printing, because the body will be a little lower that the level of your base! It will also work your way, but I will be building a new body soon which also holds the speaker and Neo Pixel, so maybe it would be nice to have some room available...kind of like this!
Because the body will surpass your floor level...its kinda like this!!
hey mickey
good idea i can make an extra block as in your picture.
what about this idea?lots off spare room.little smaller then the lower block.
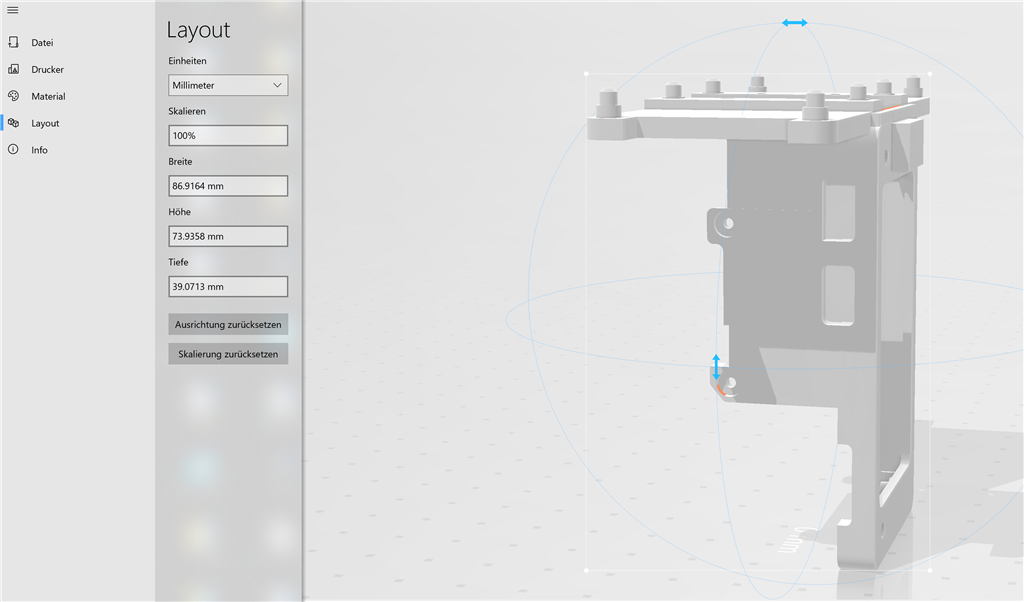
Sure, looks good...I am making a test print to make sure everything works out fine, then I will send you the new part so you can check if it works with your design!! It looks like this...