cE9s4PsOgeBQIORwjd5!~~60_1-634818020230156250.jpg)
Lupuc4g~~60_35-634706297915000000.jpg)
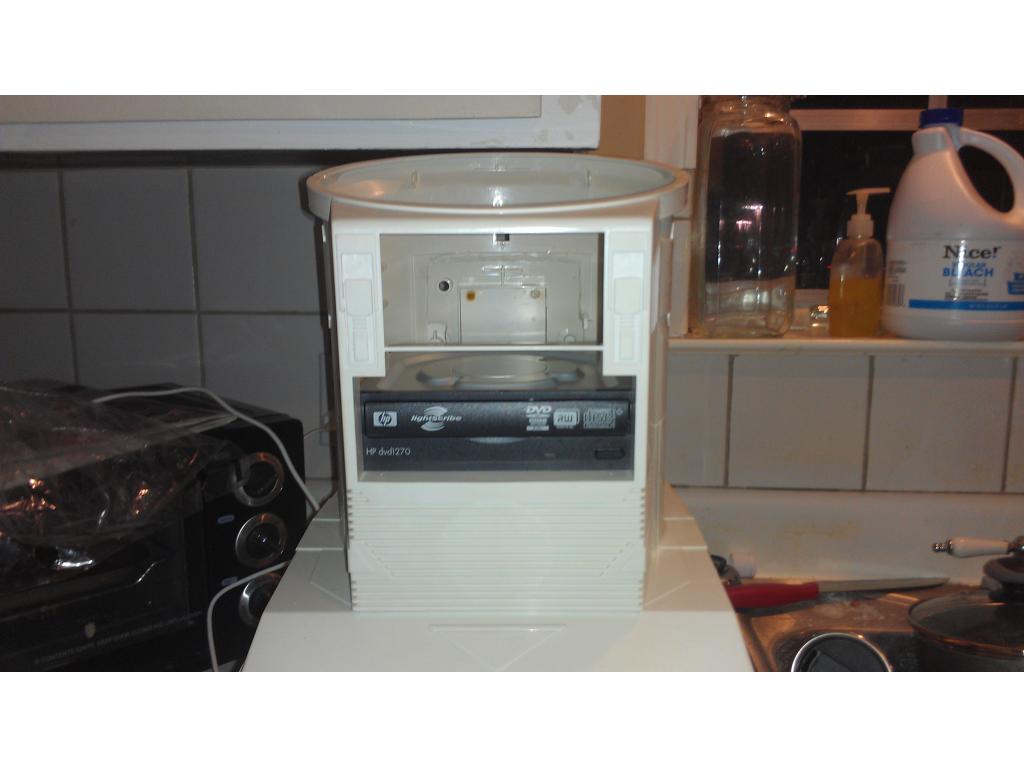
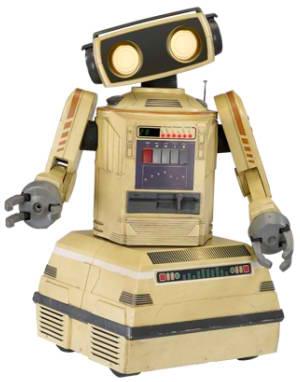
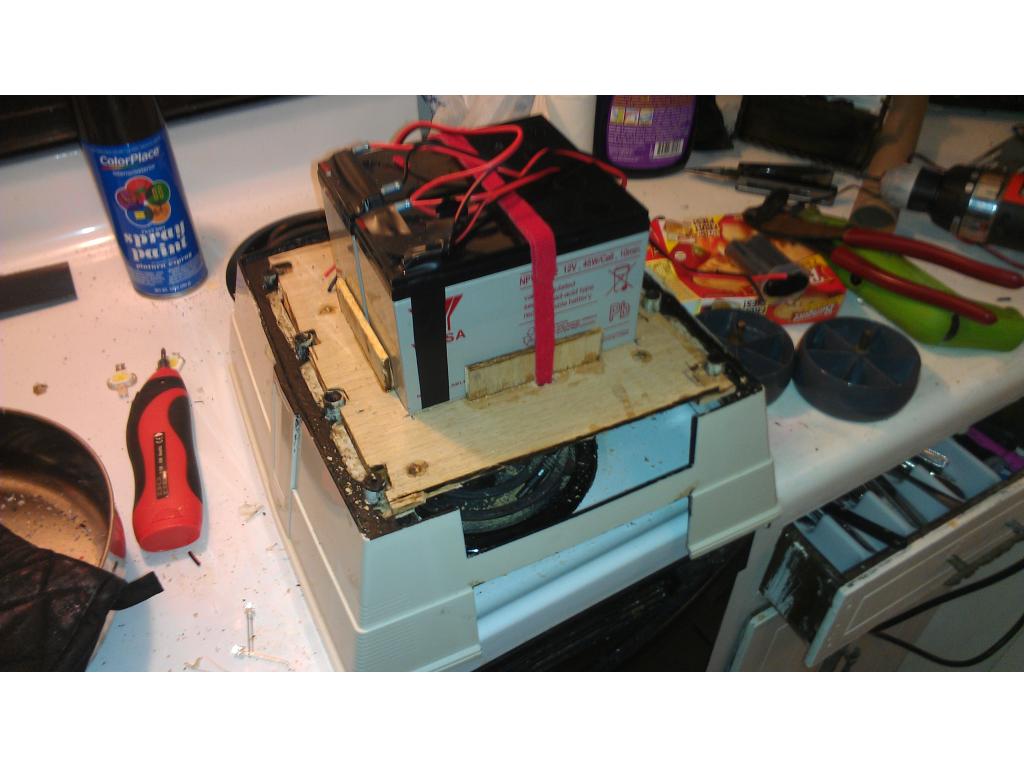
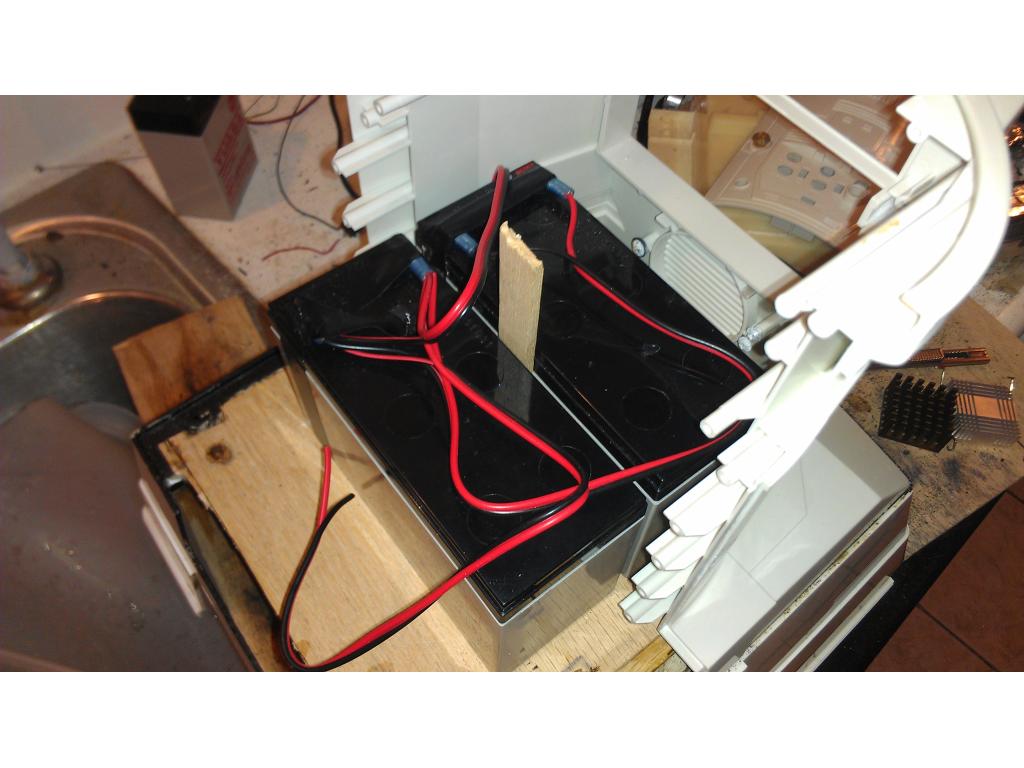
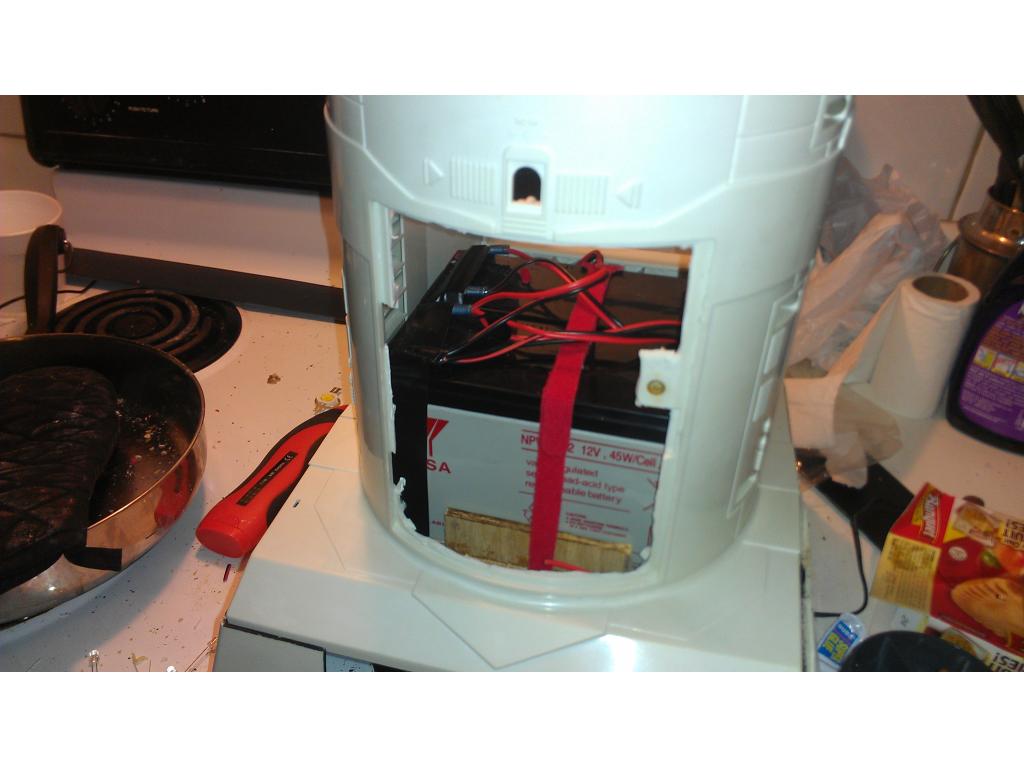
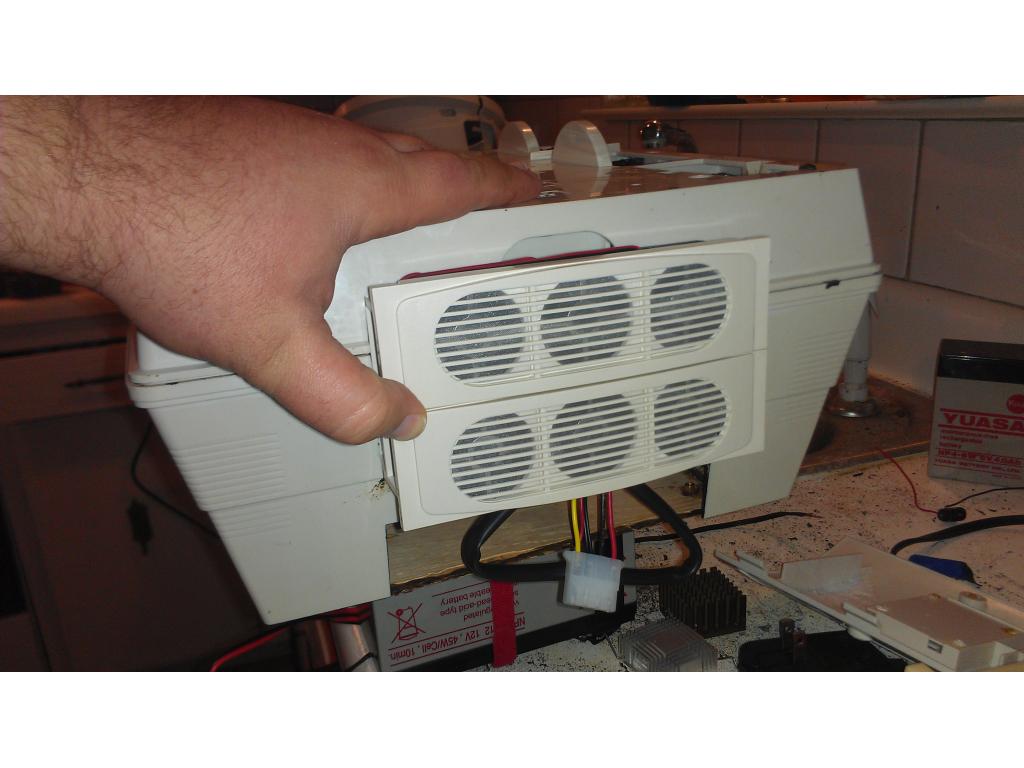
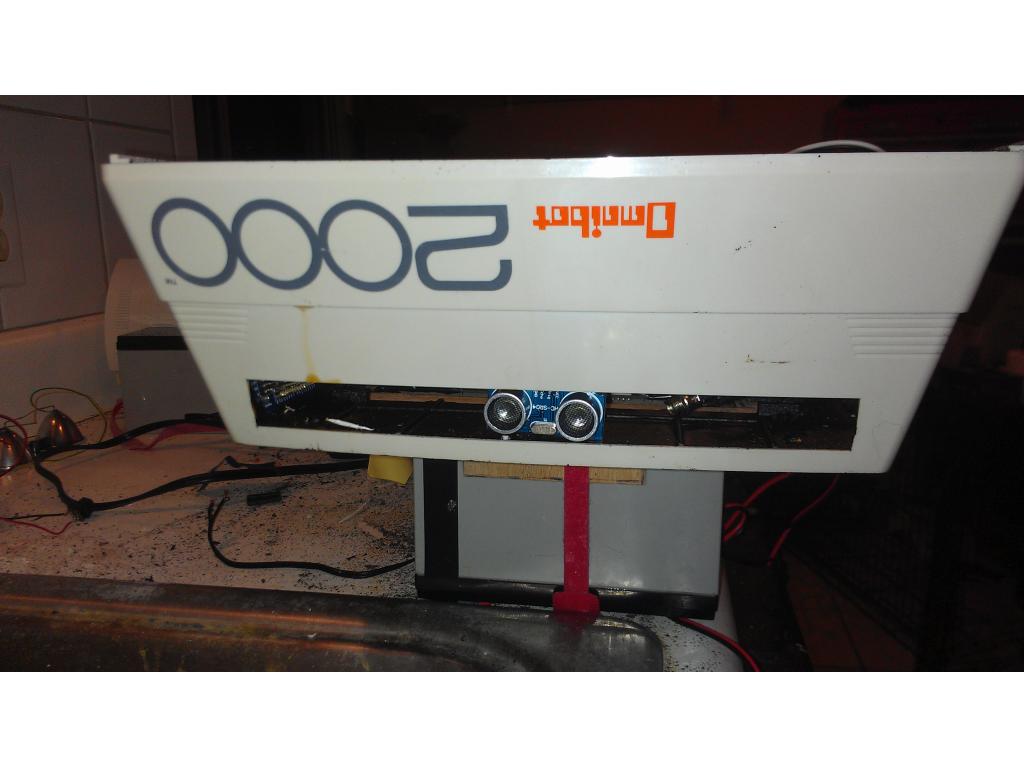
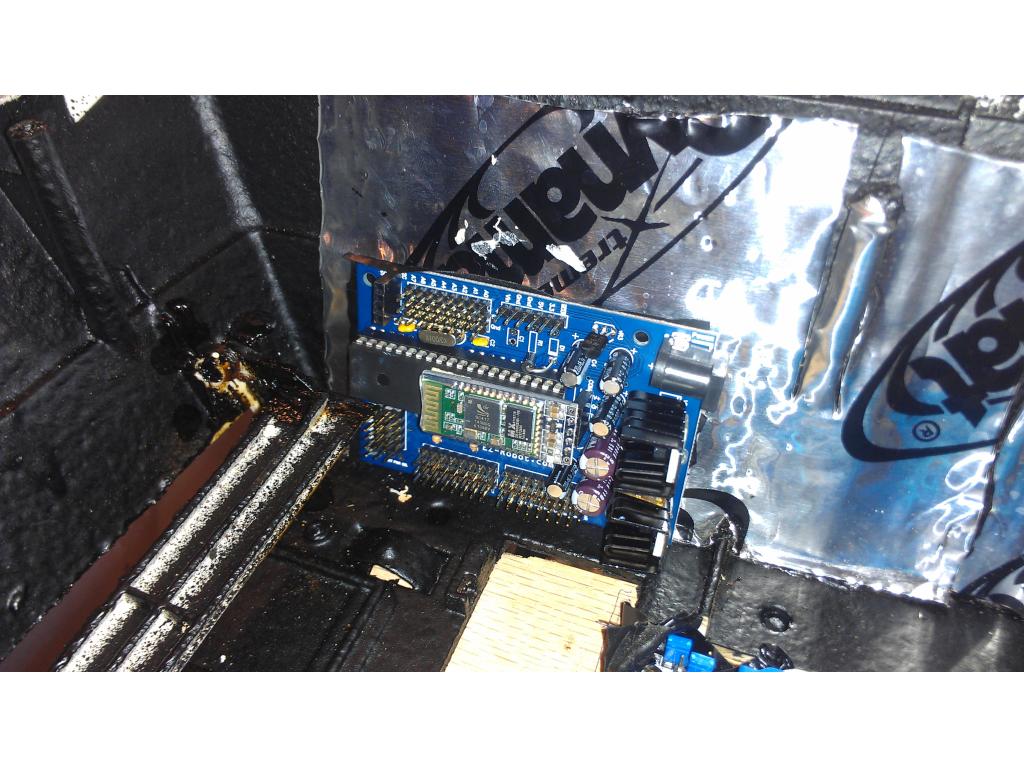
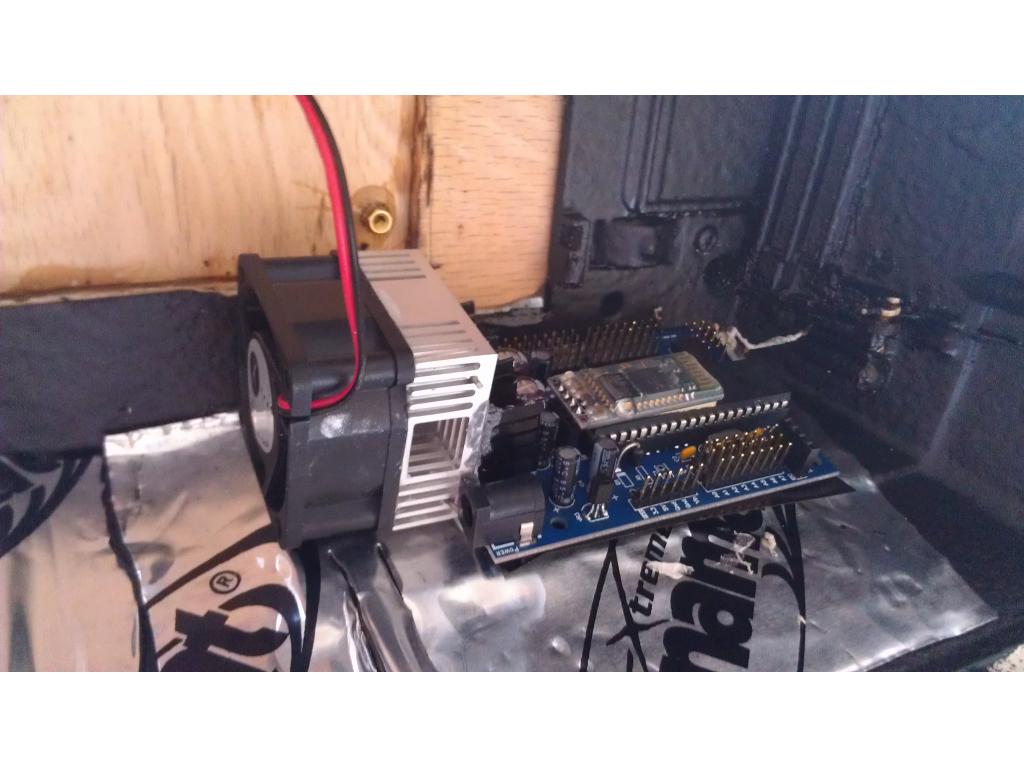
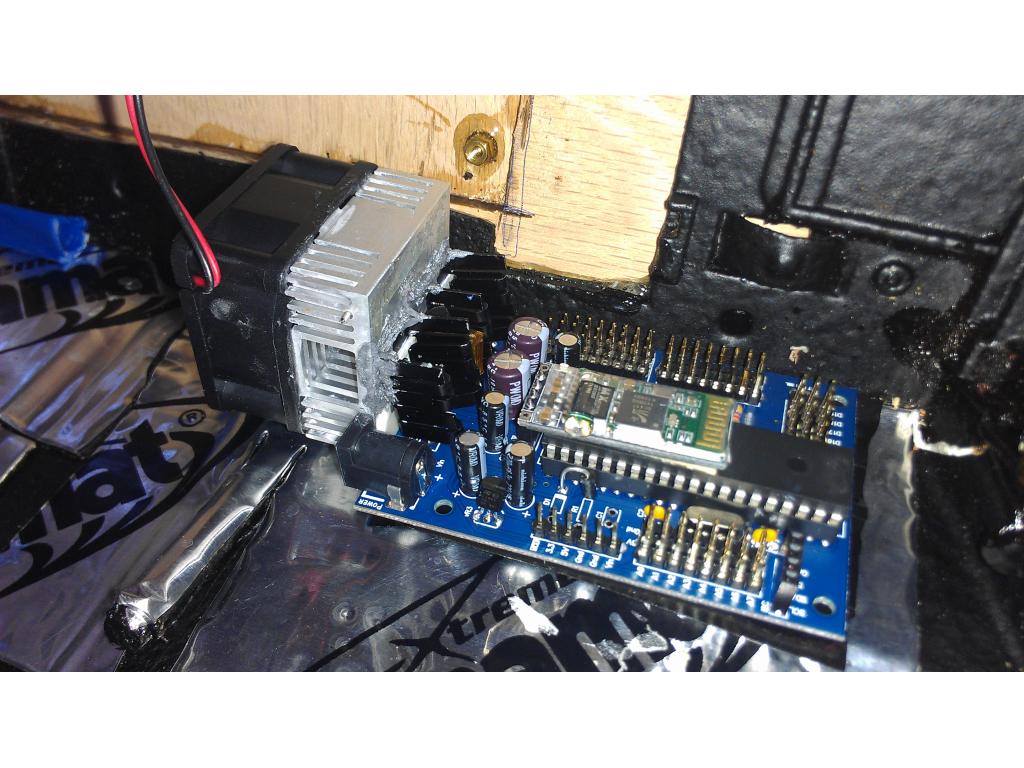
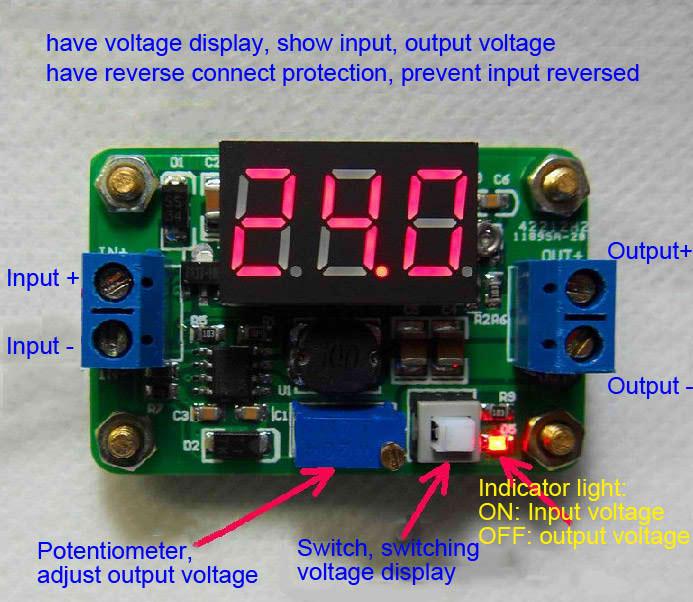
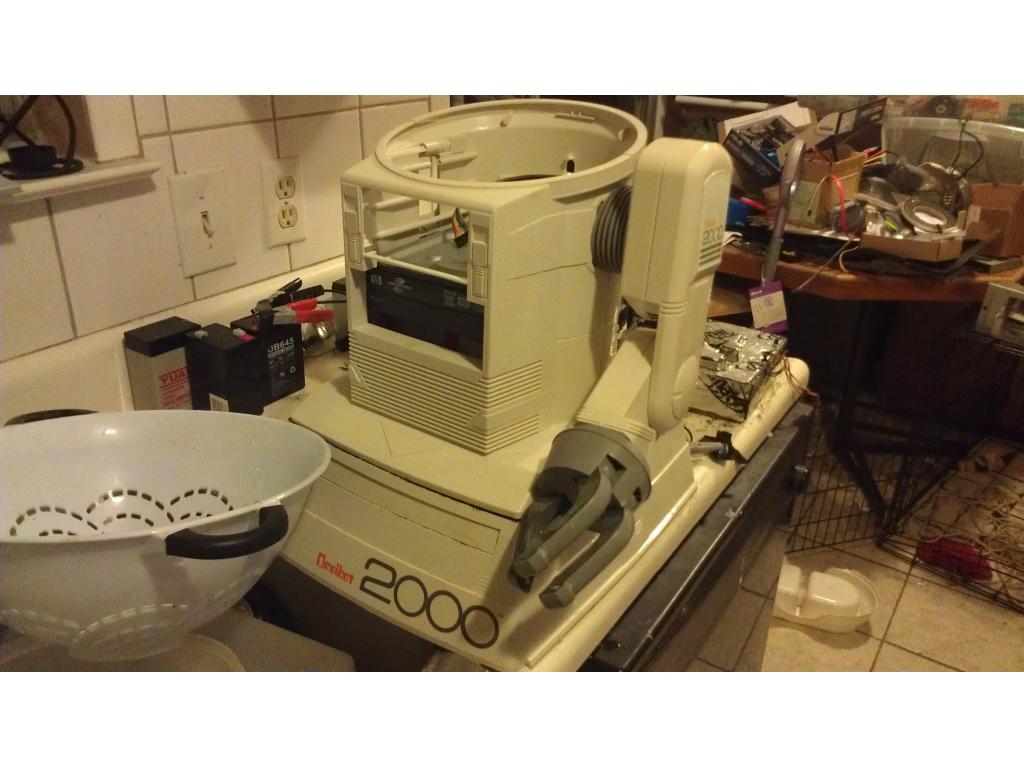
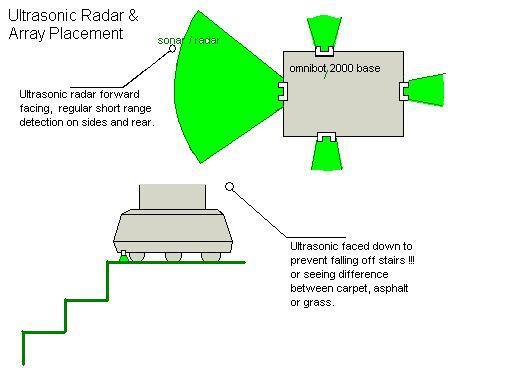
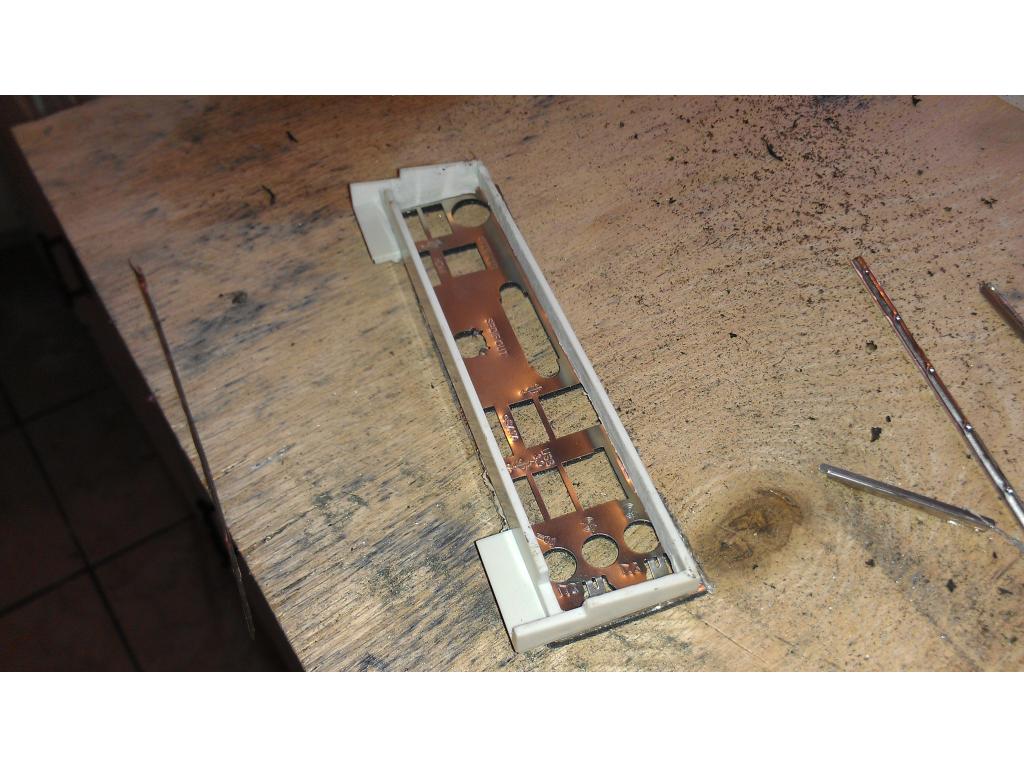
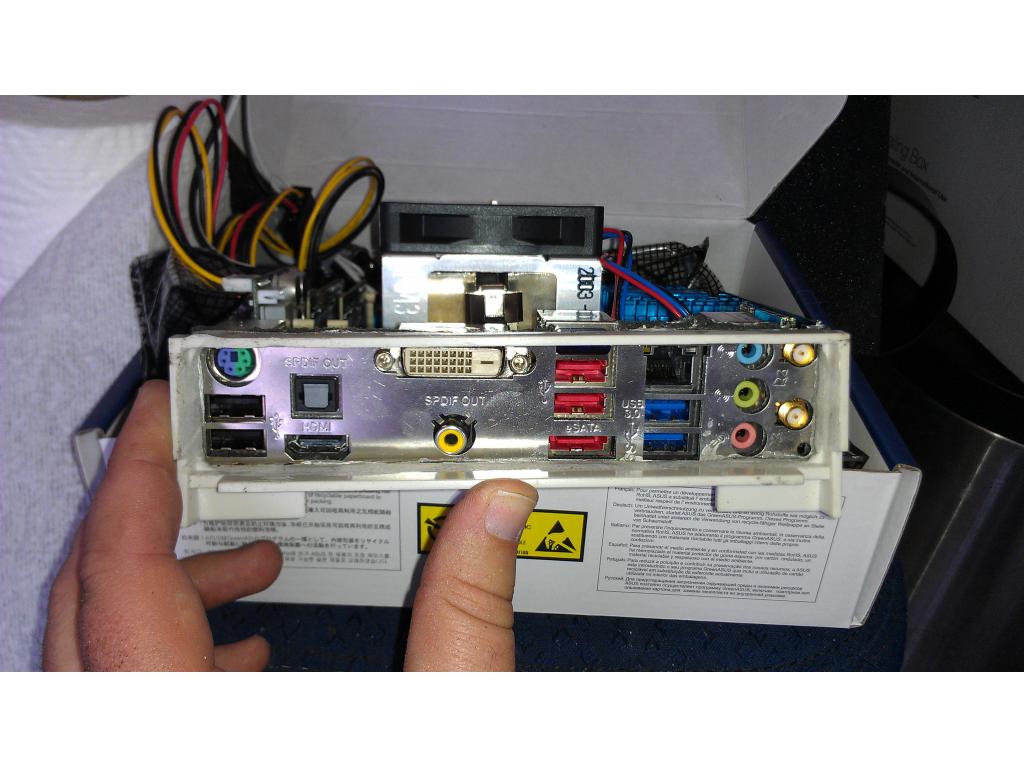
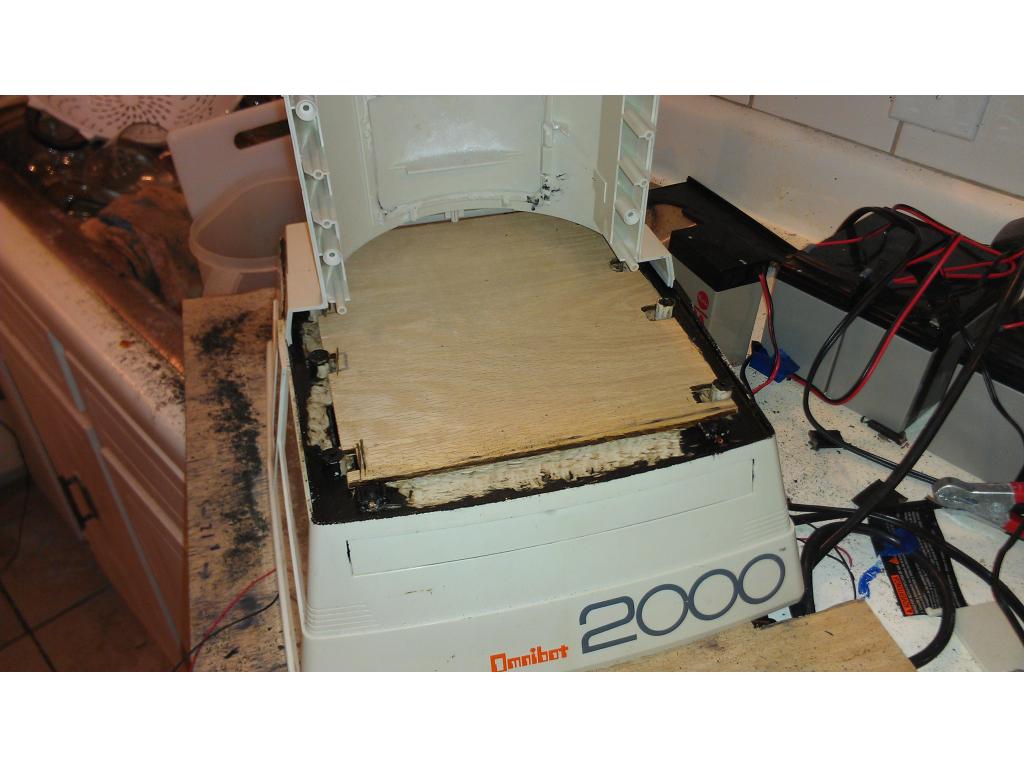
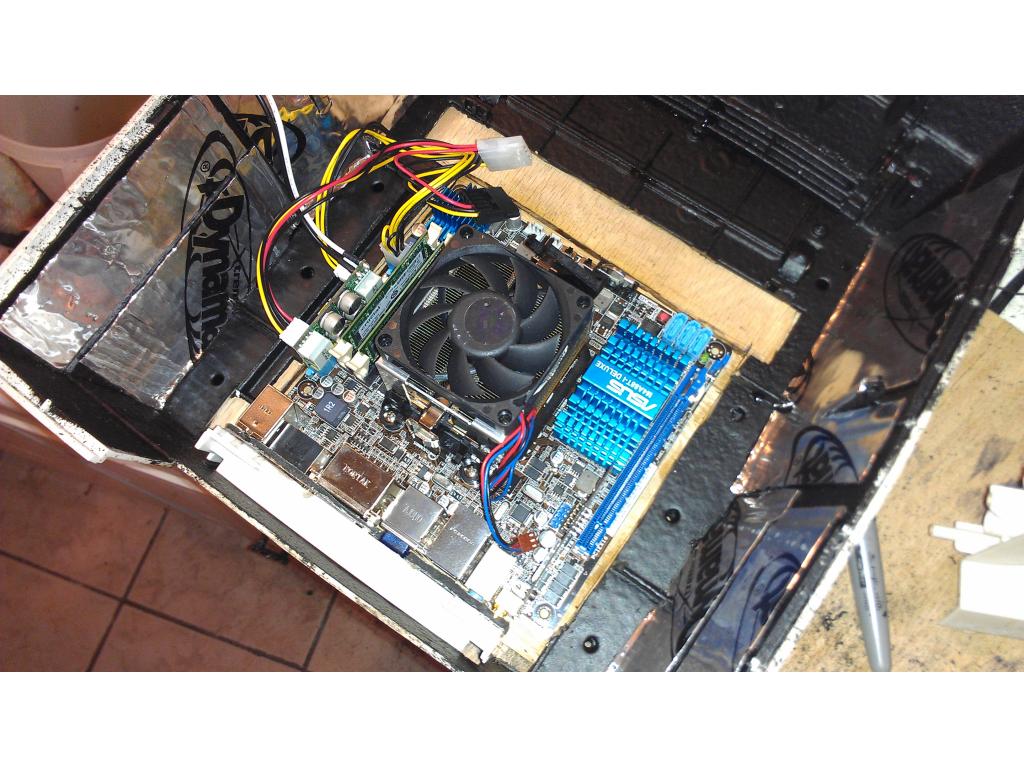
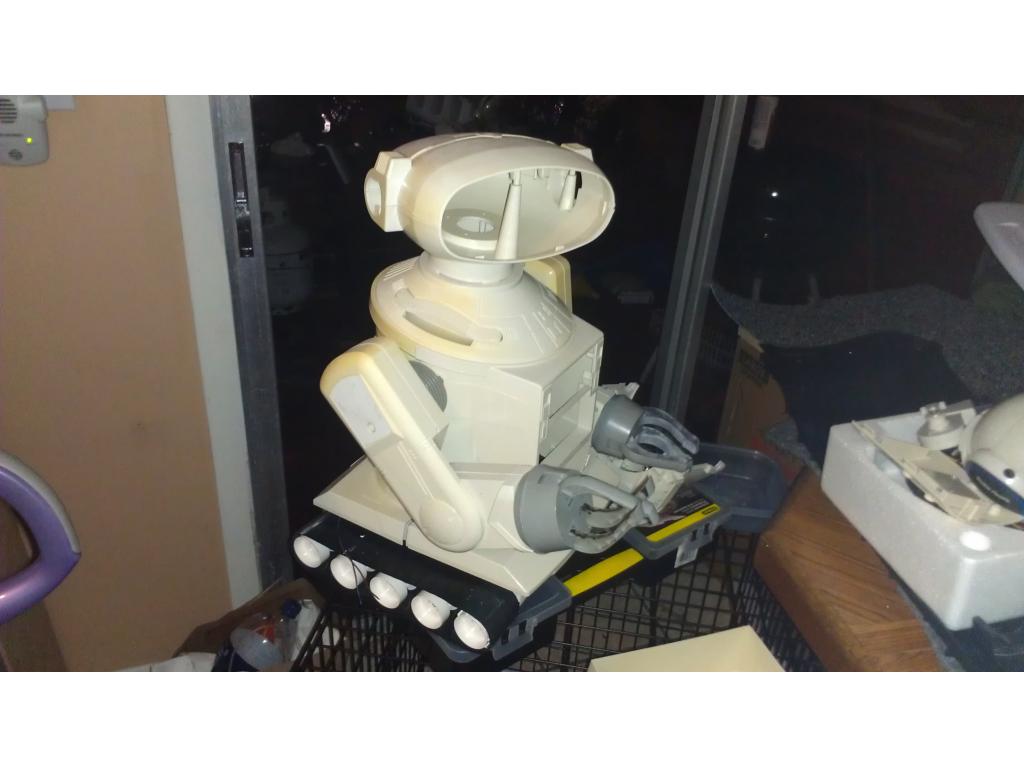
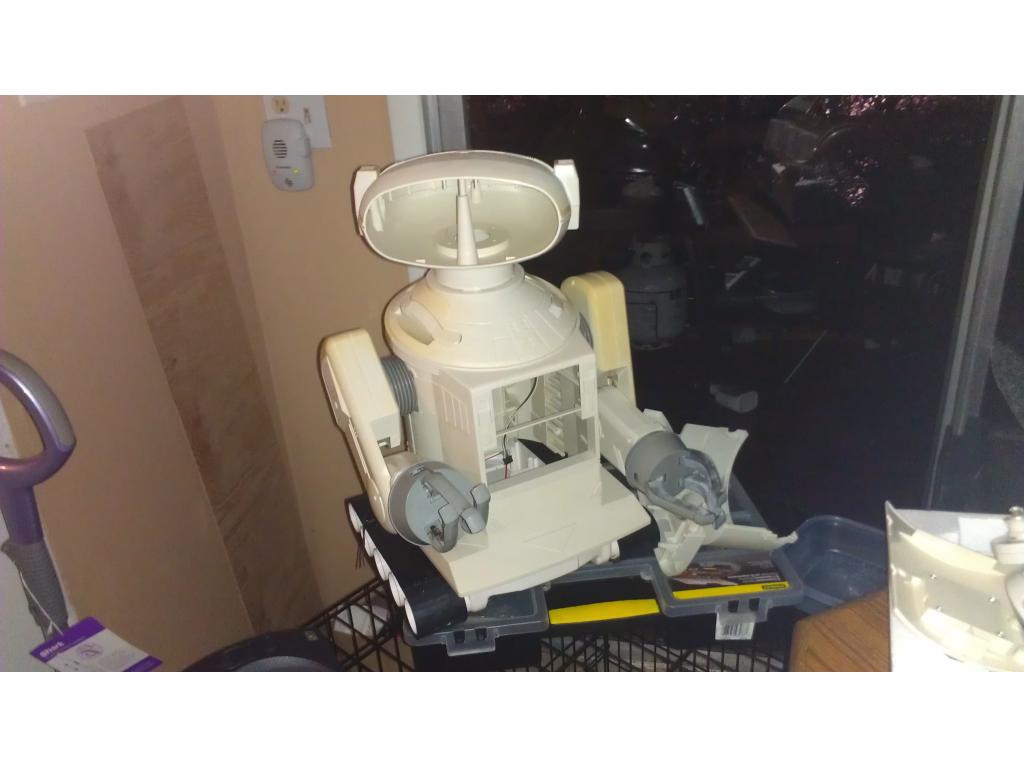
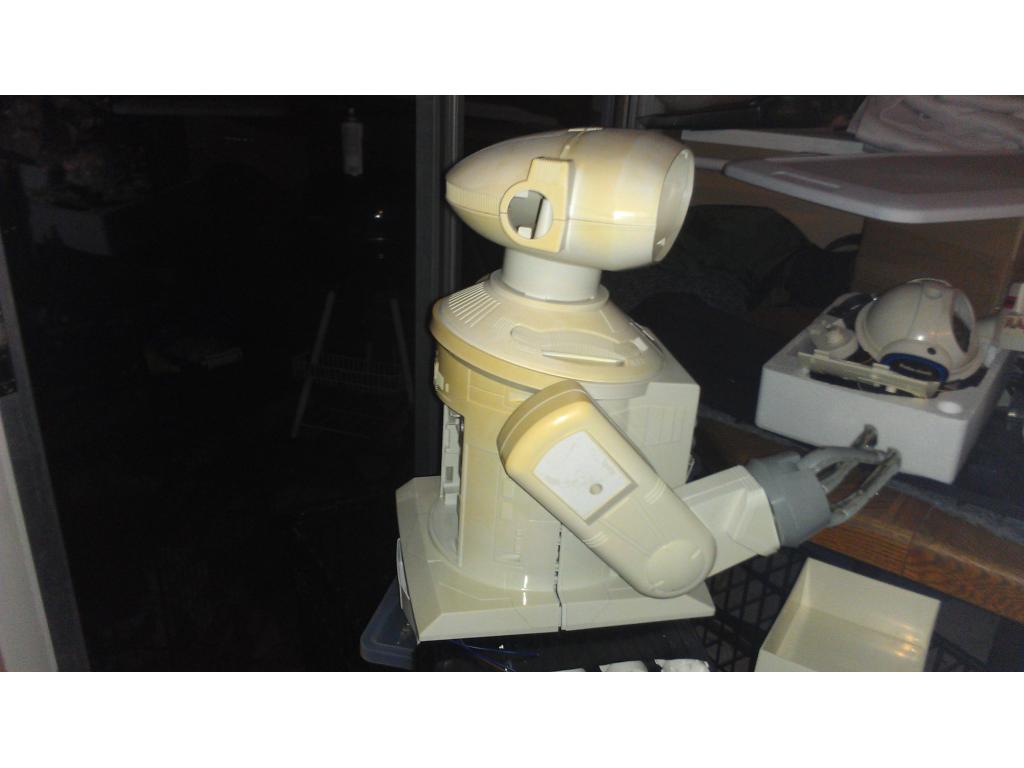
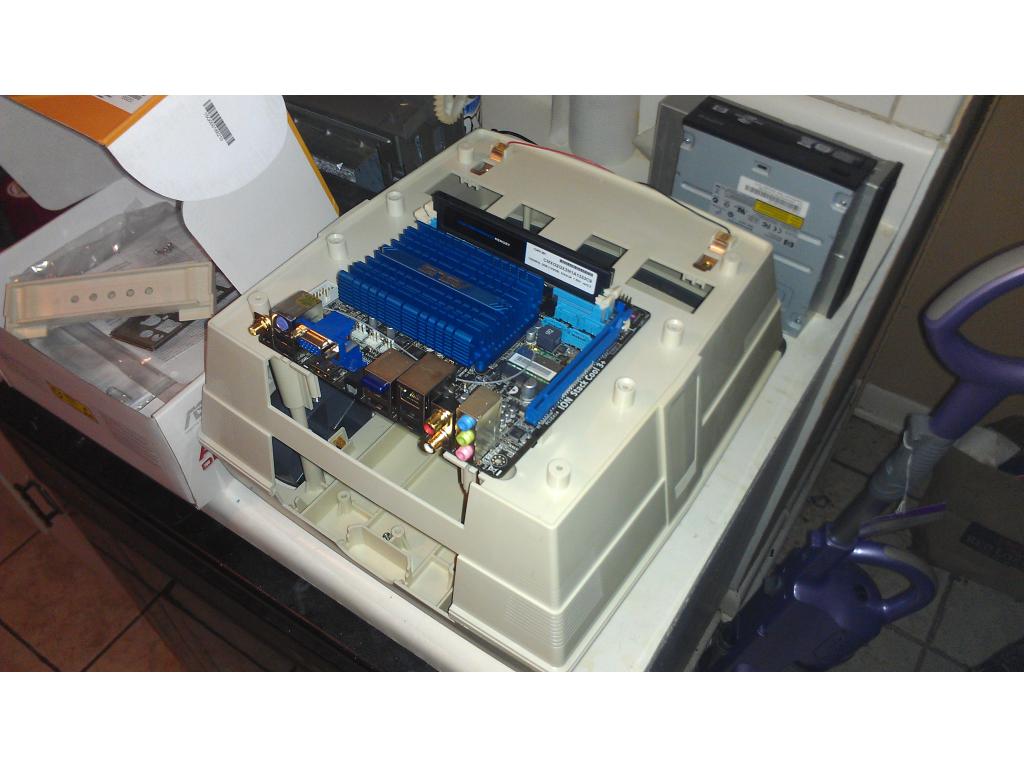
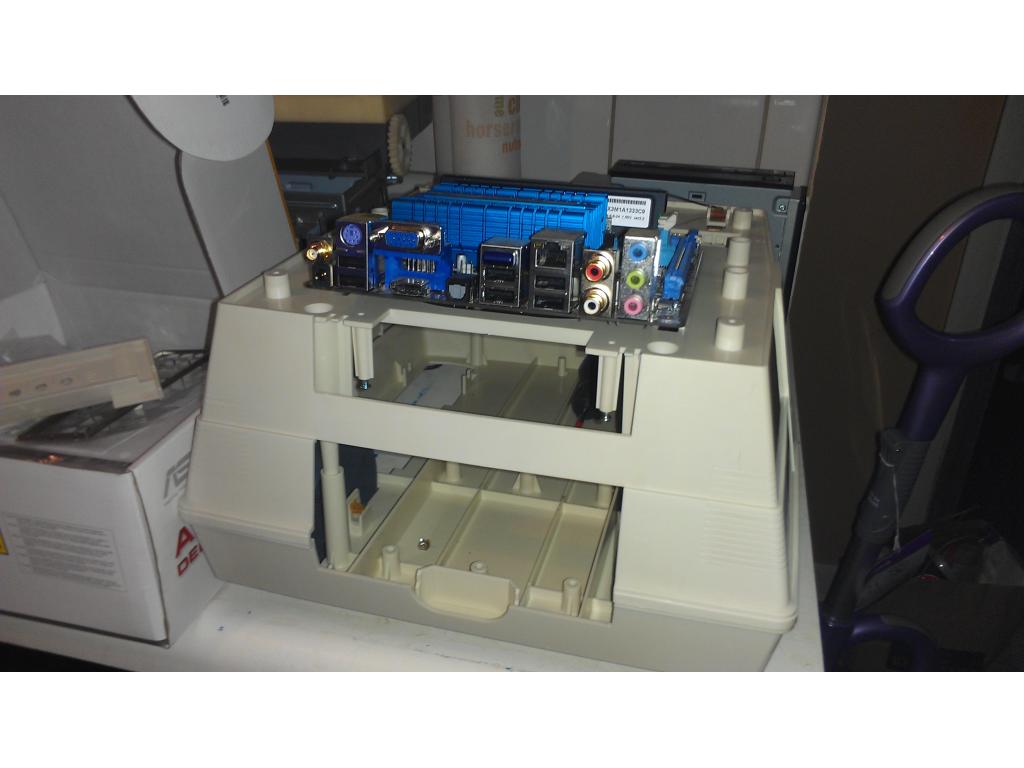
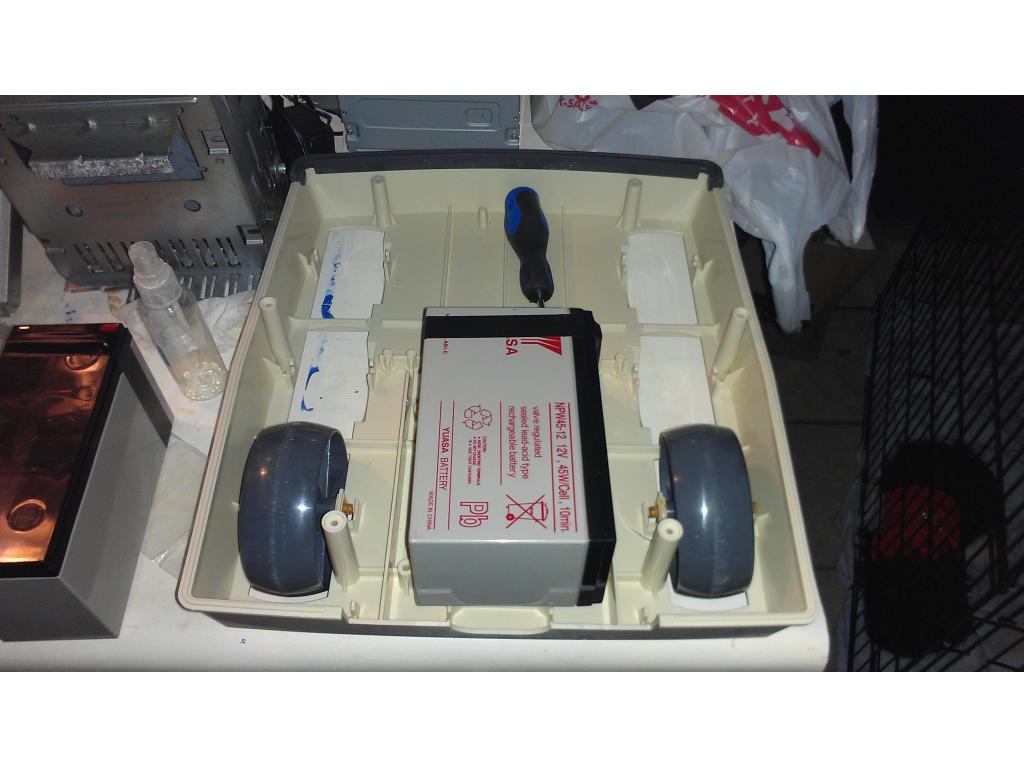
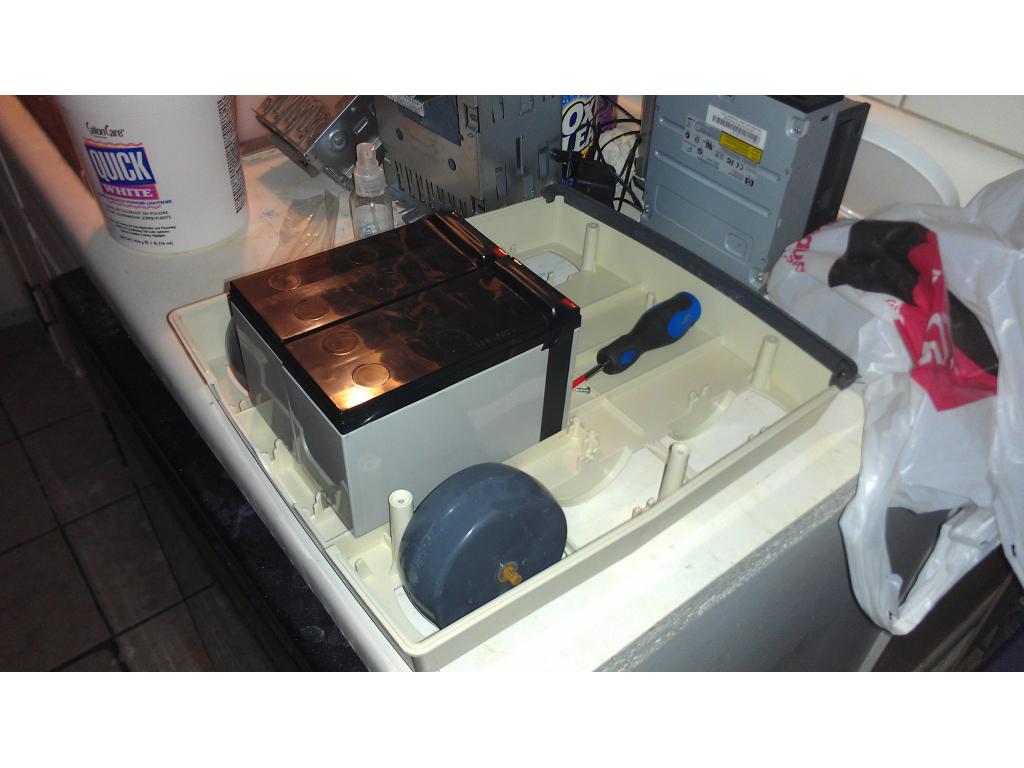
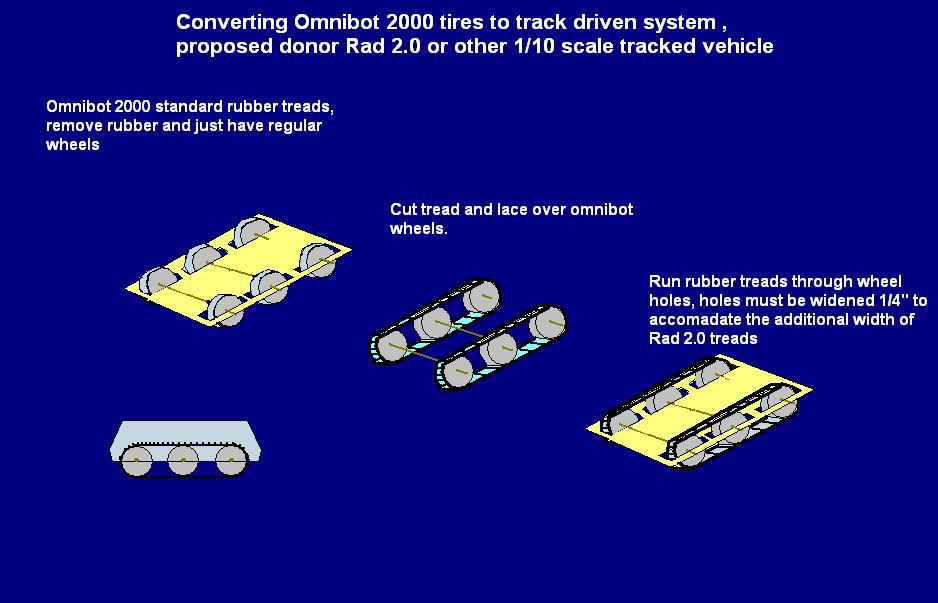


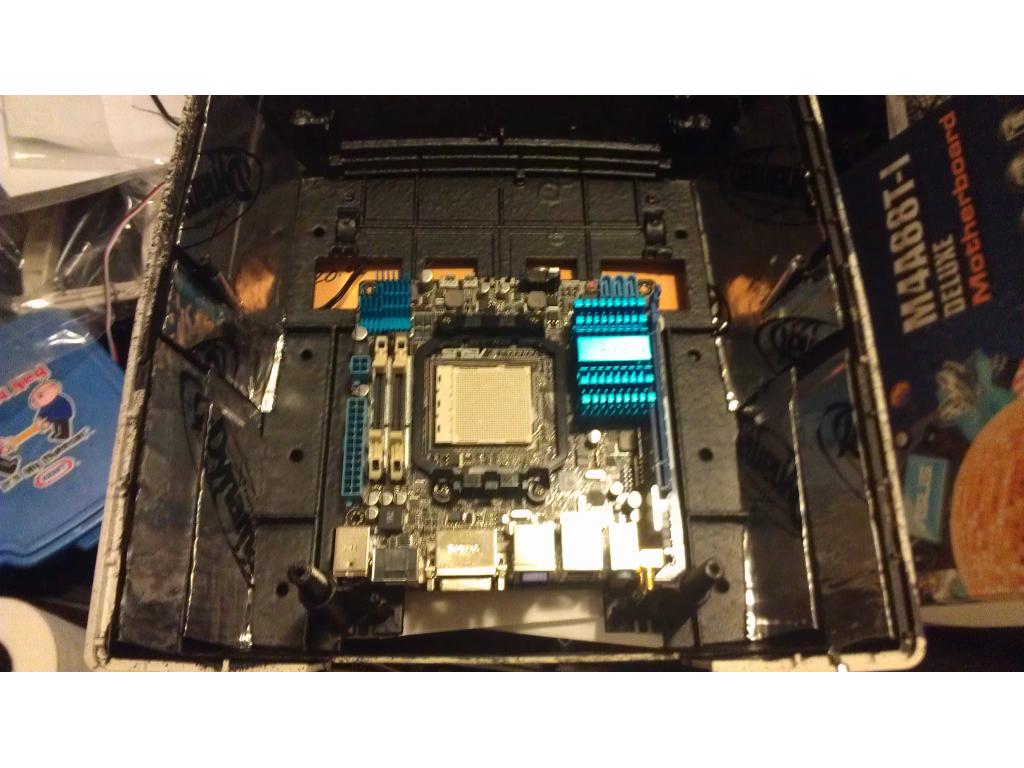
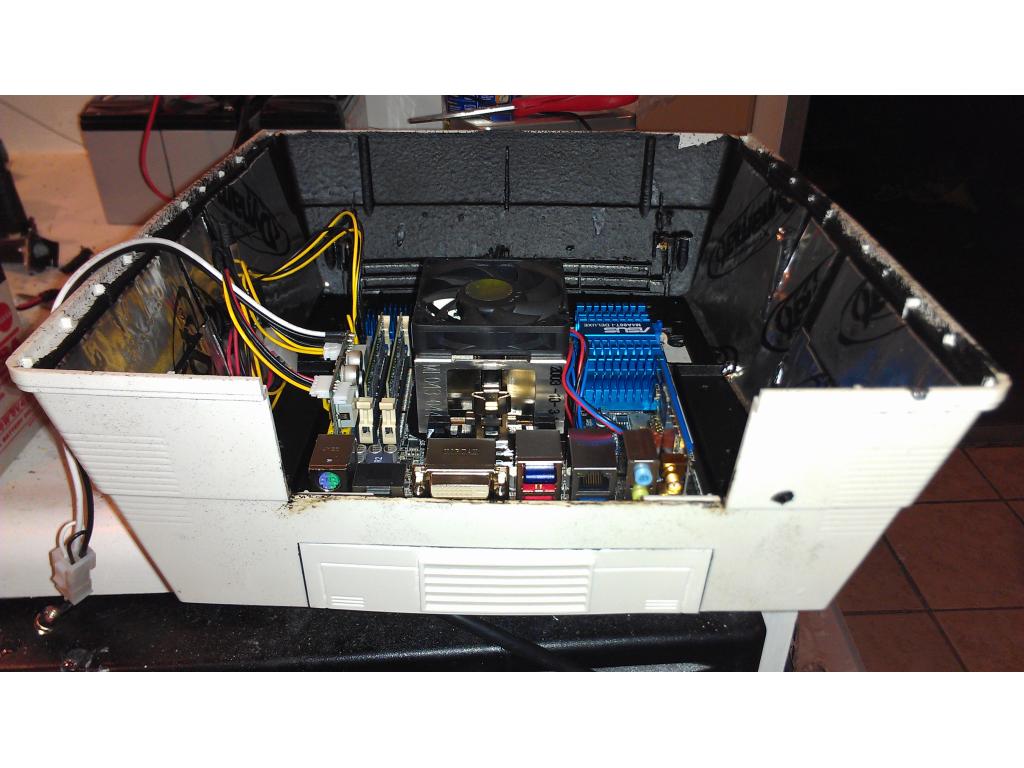
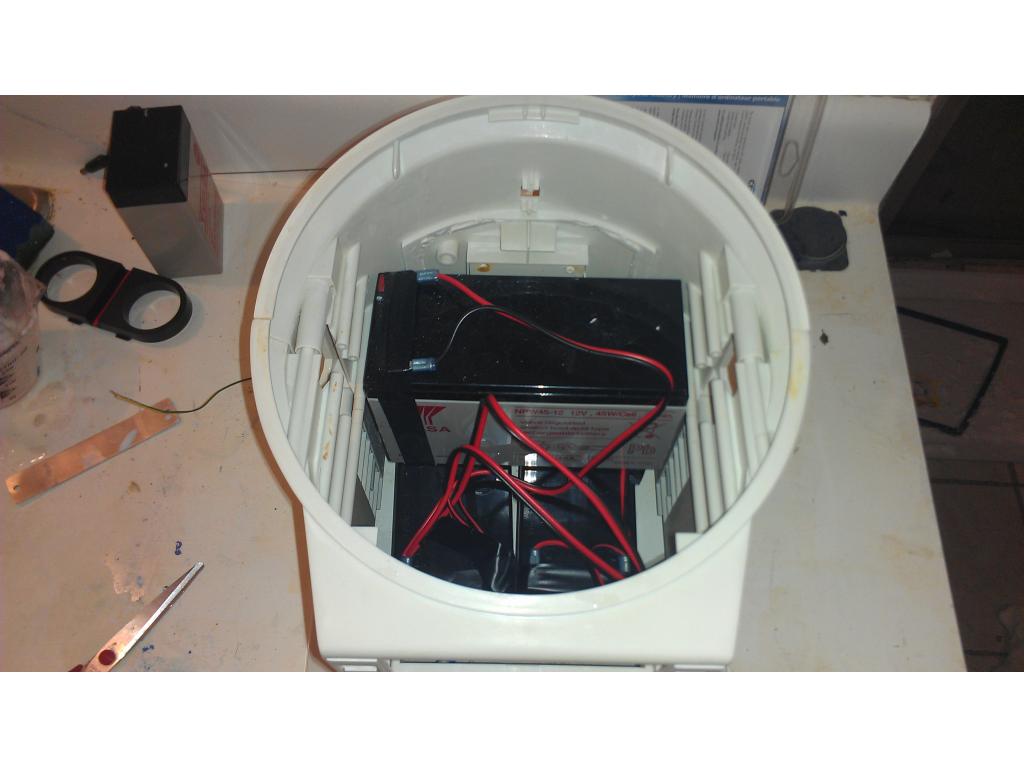
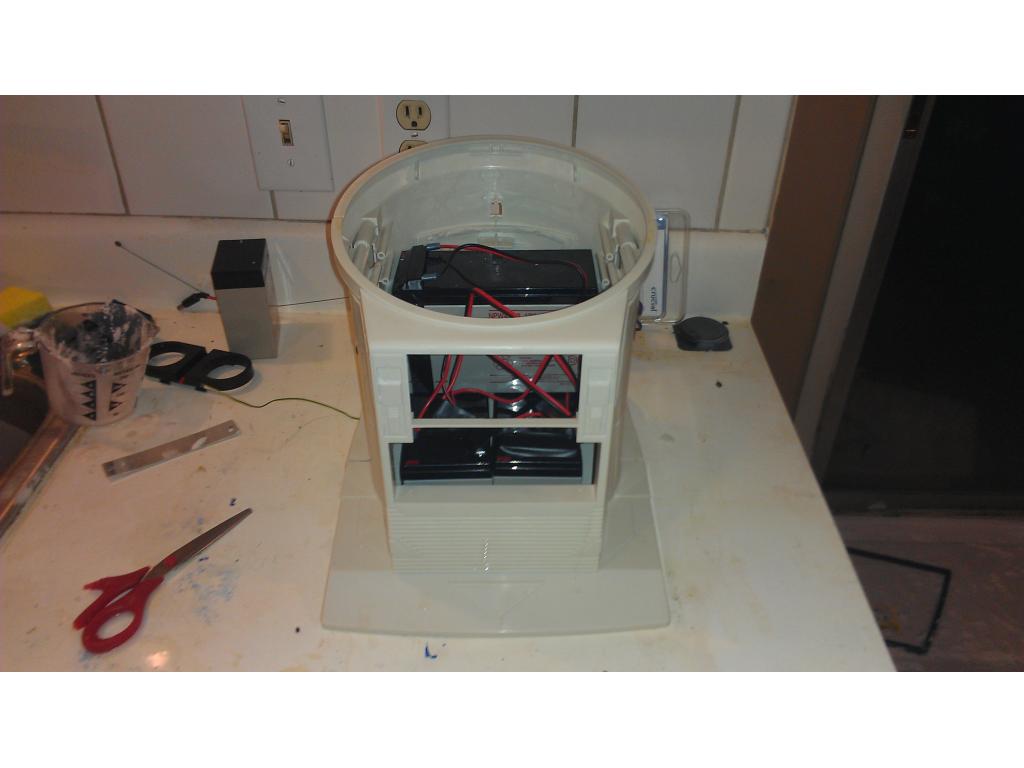
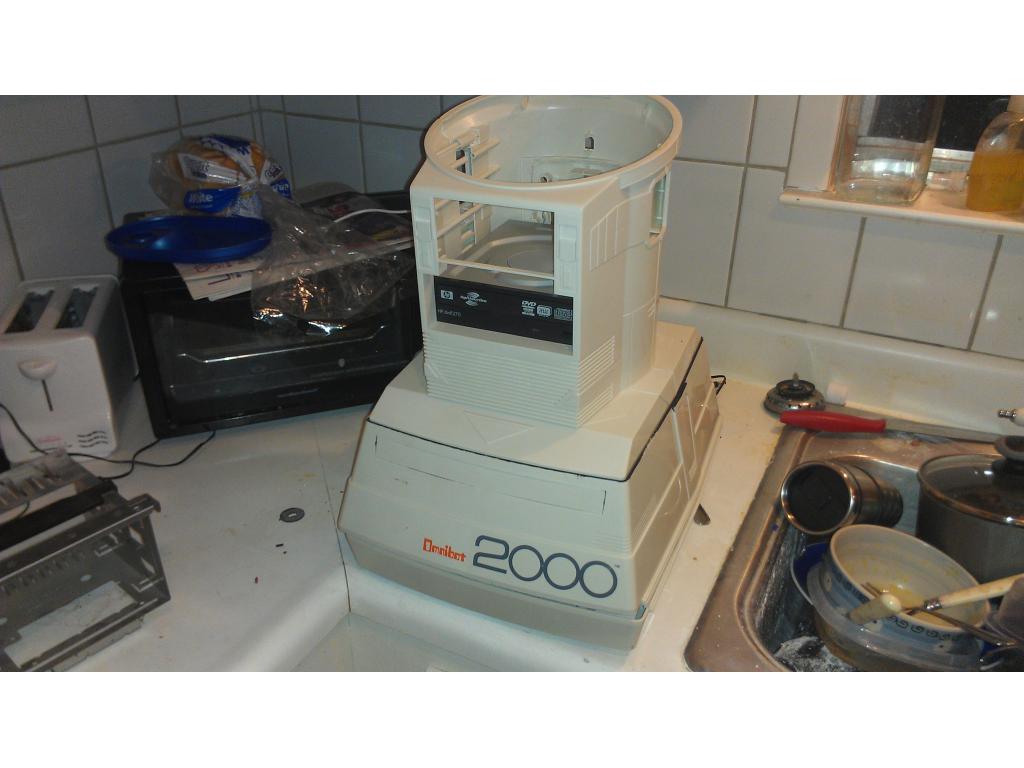
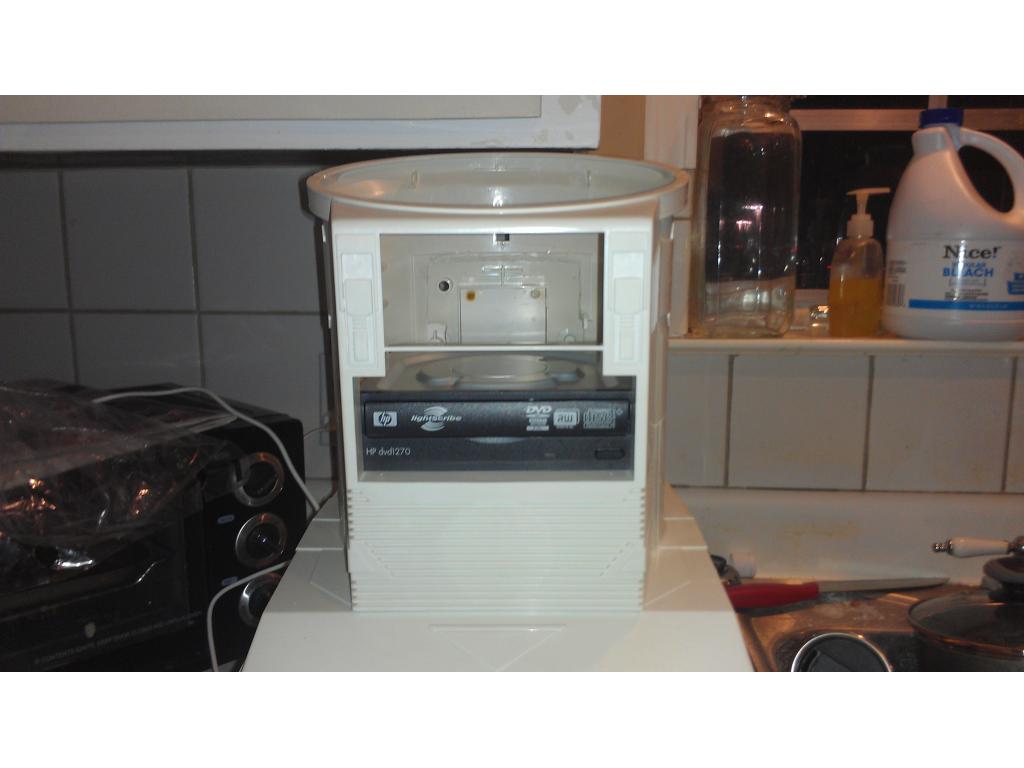
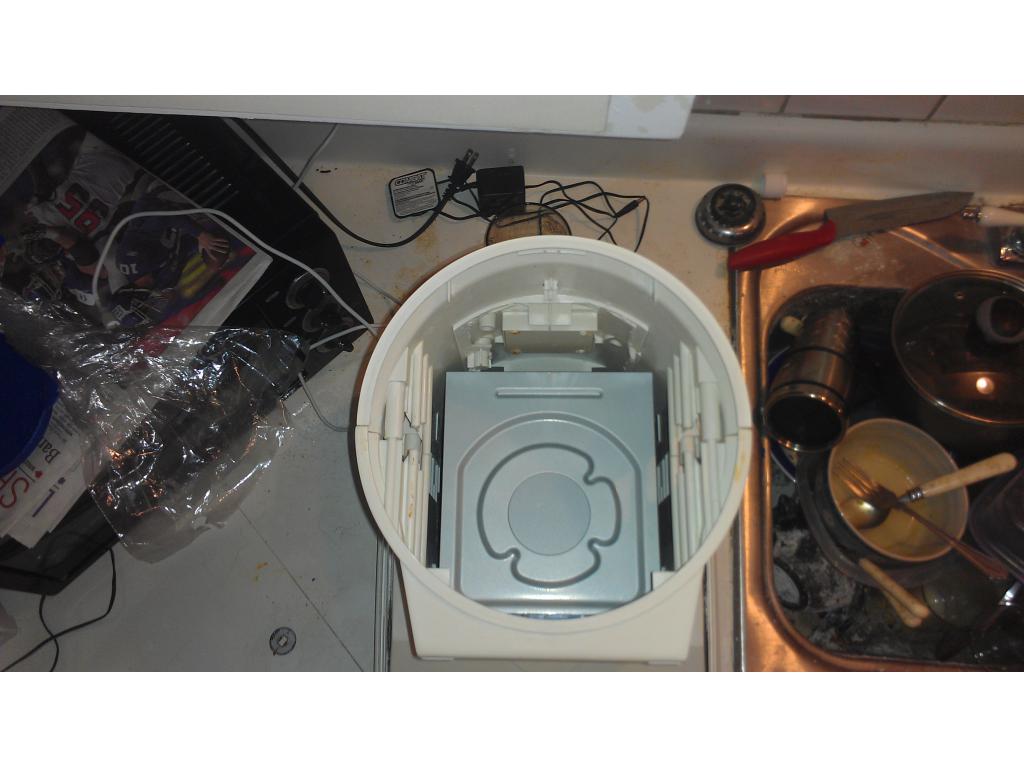
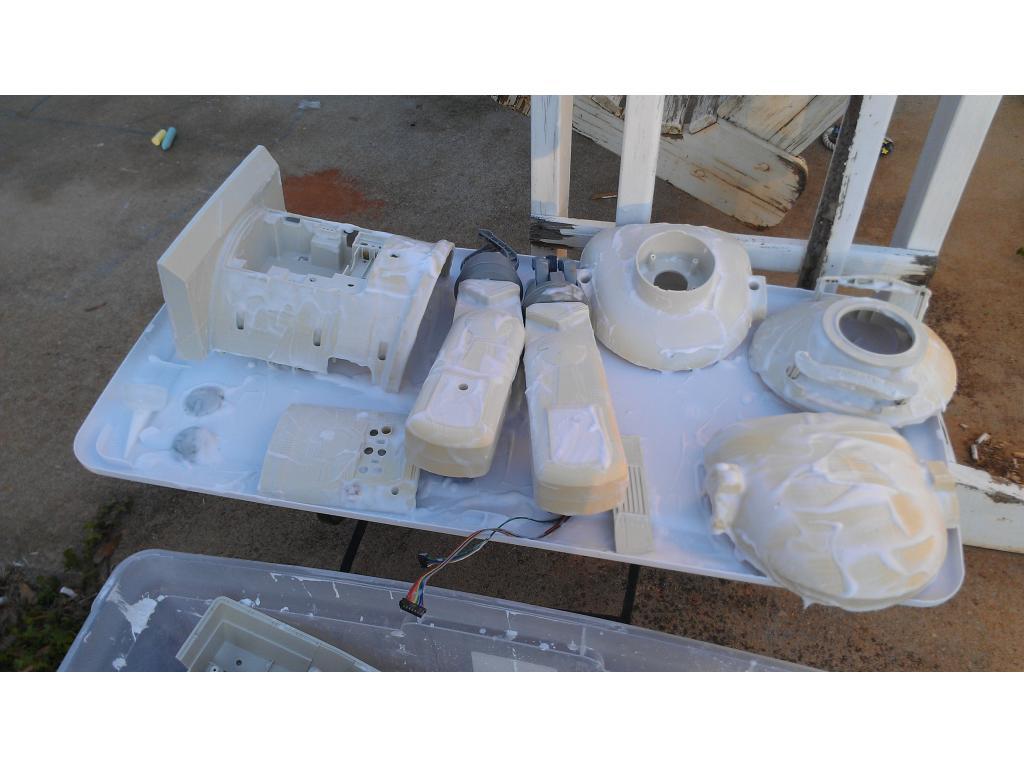
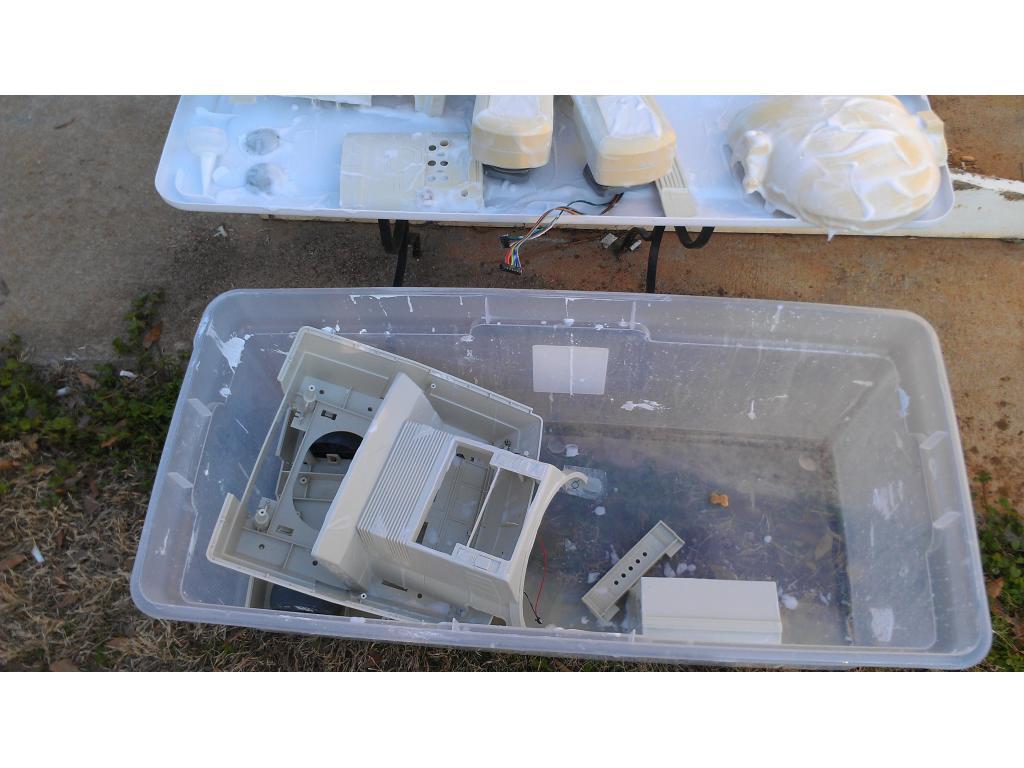
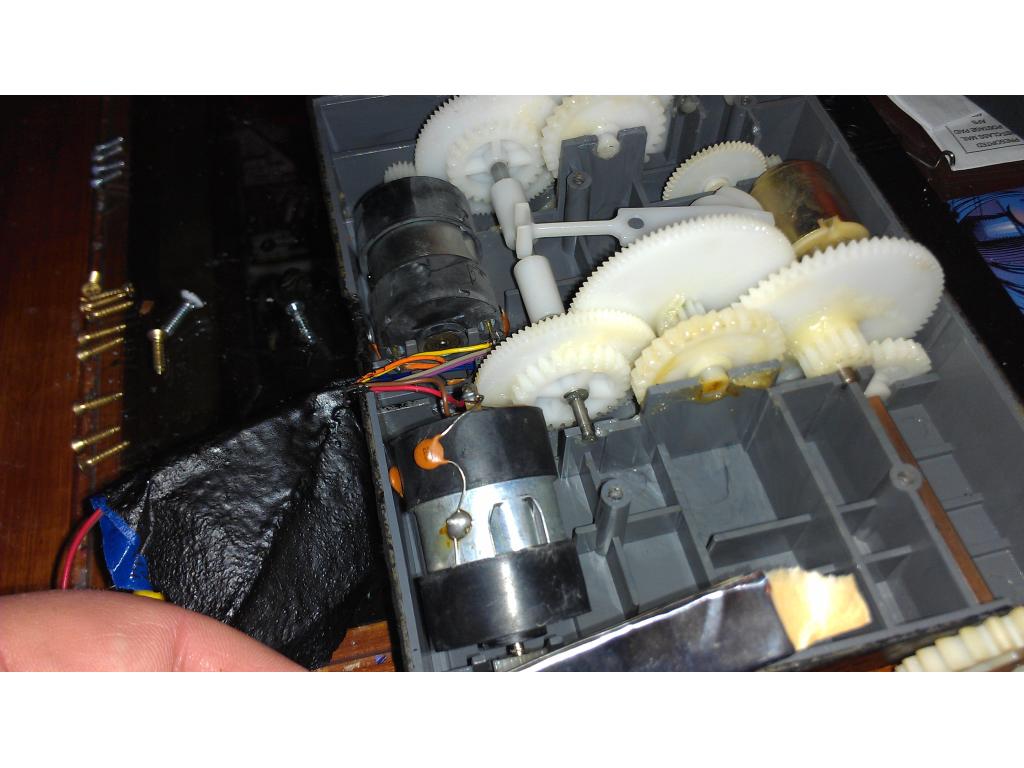
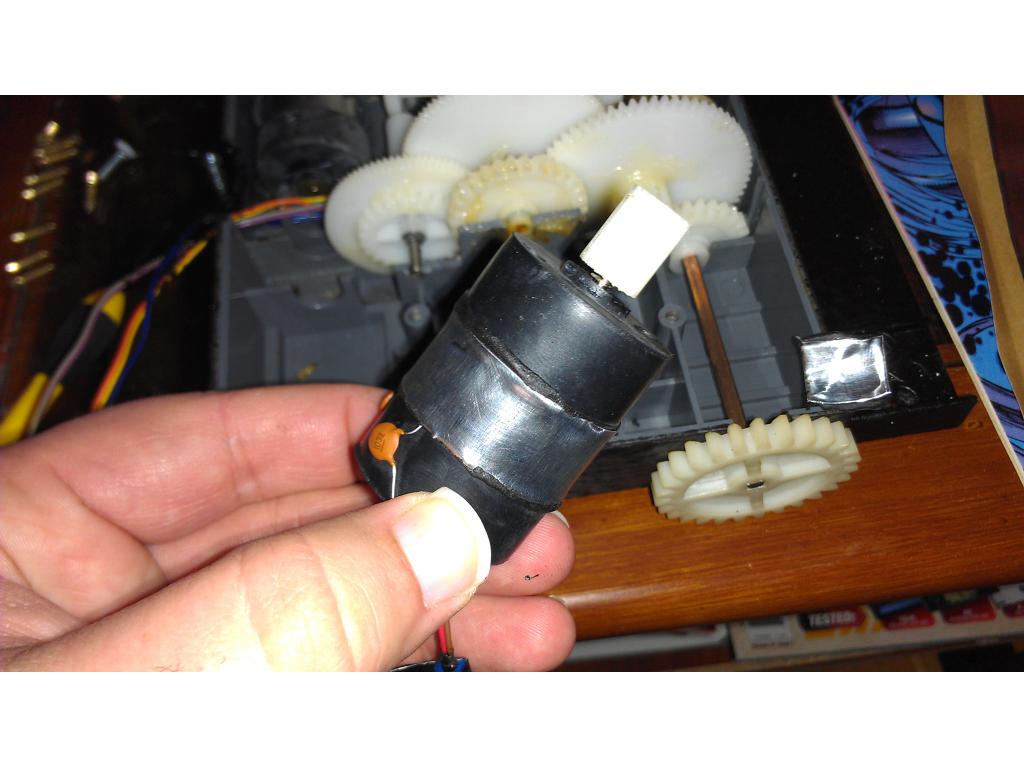
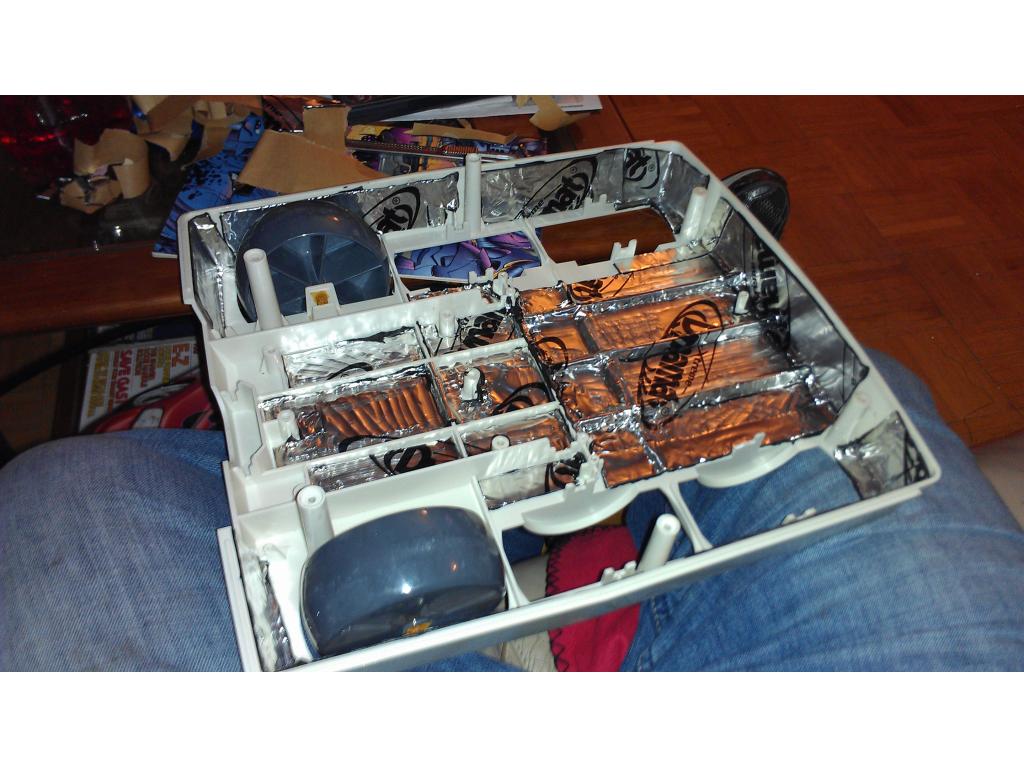
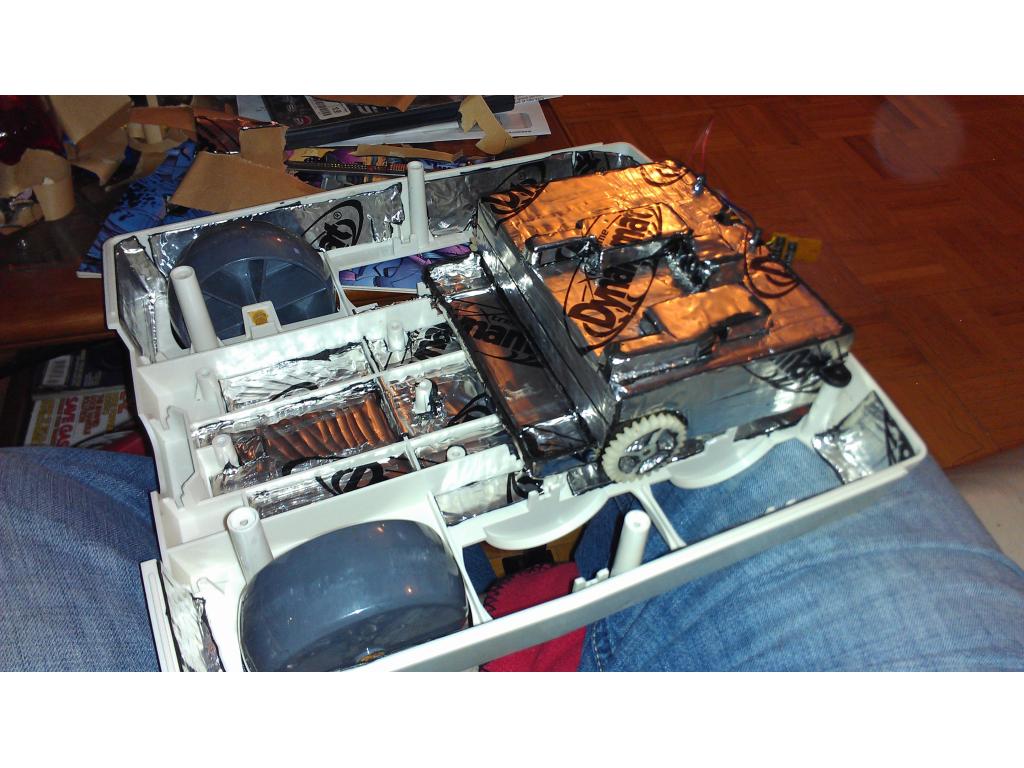
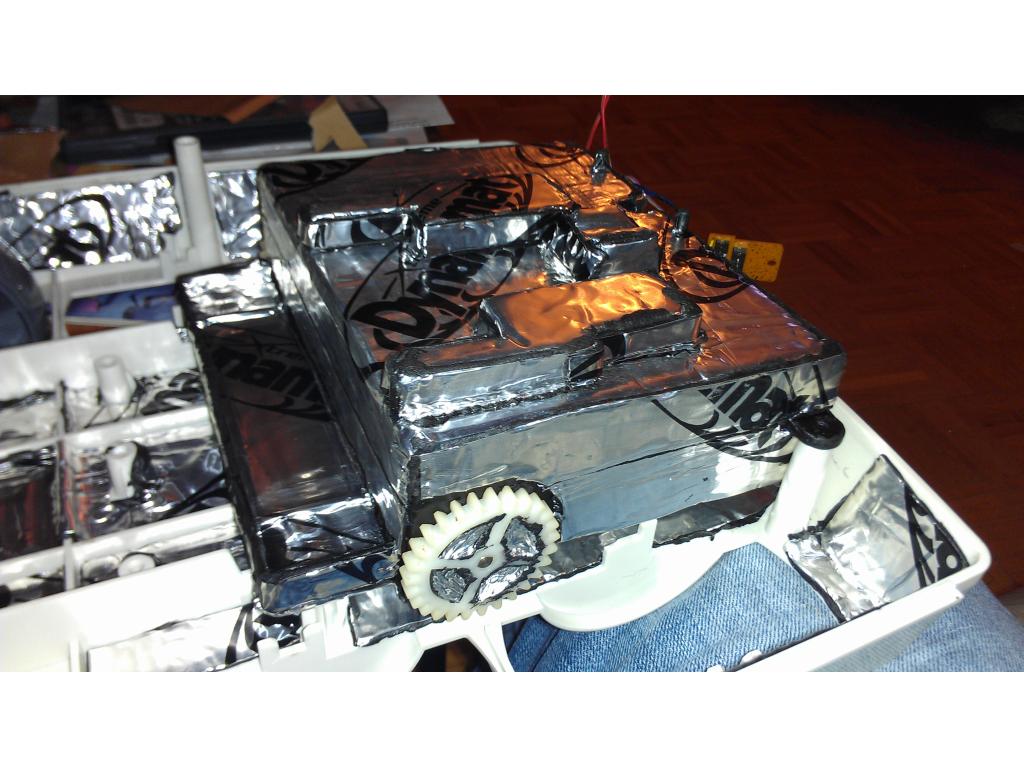
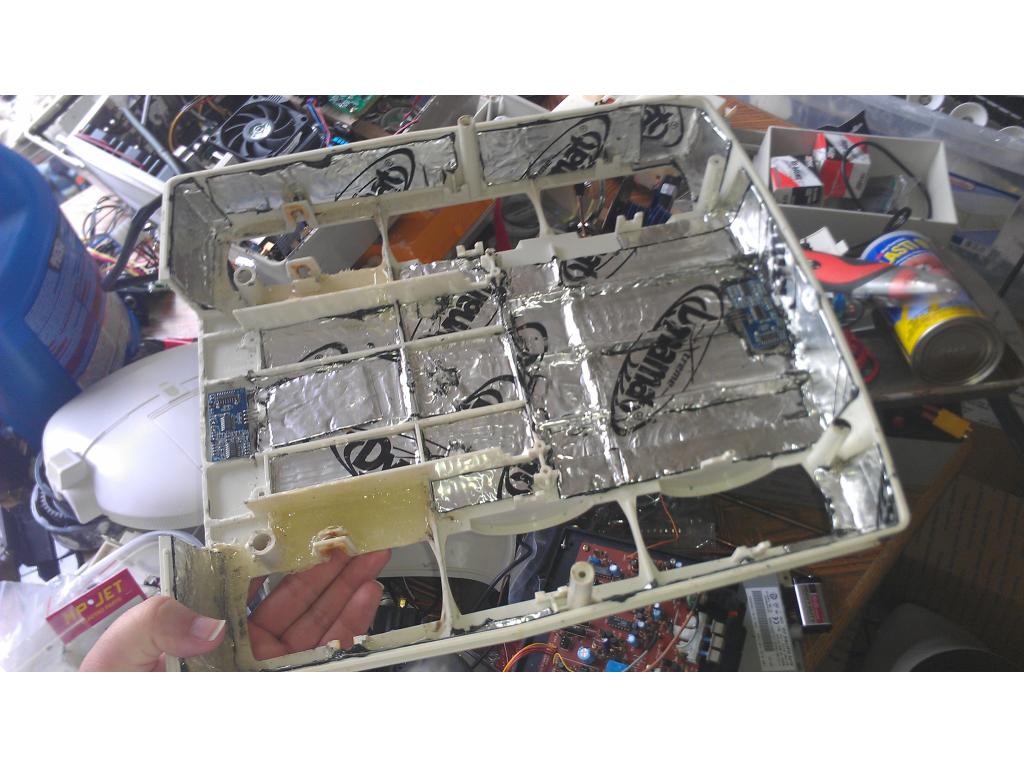
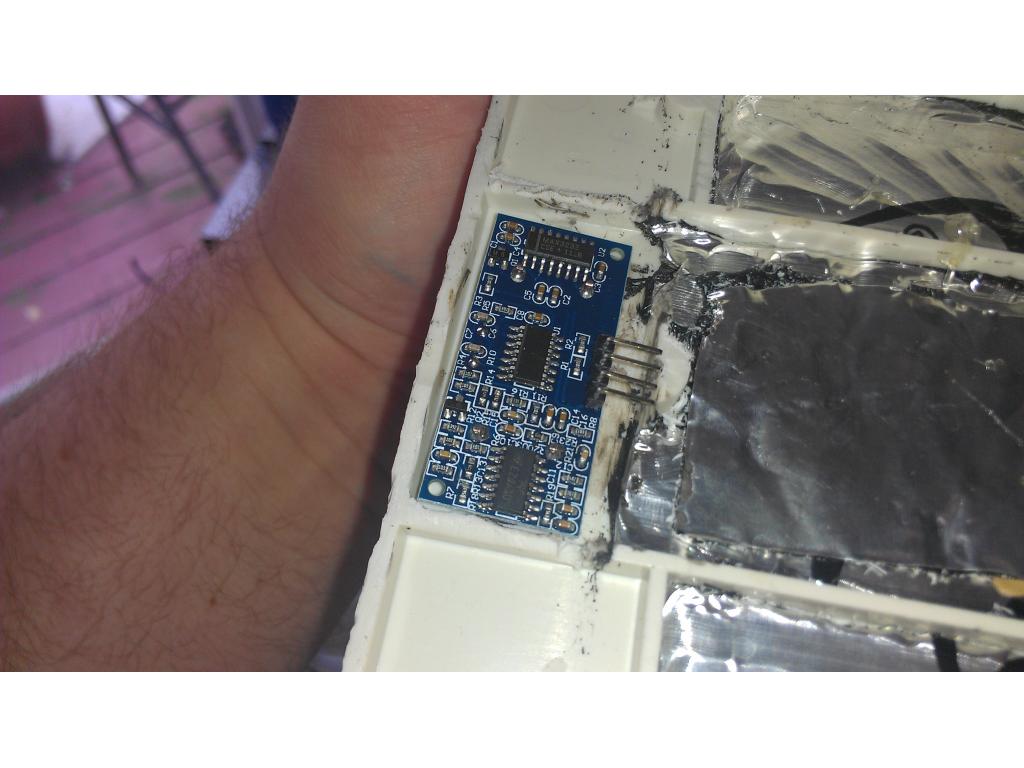
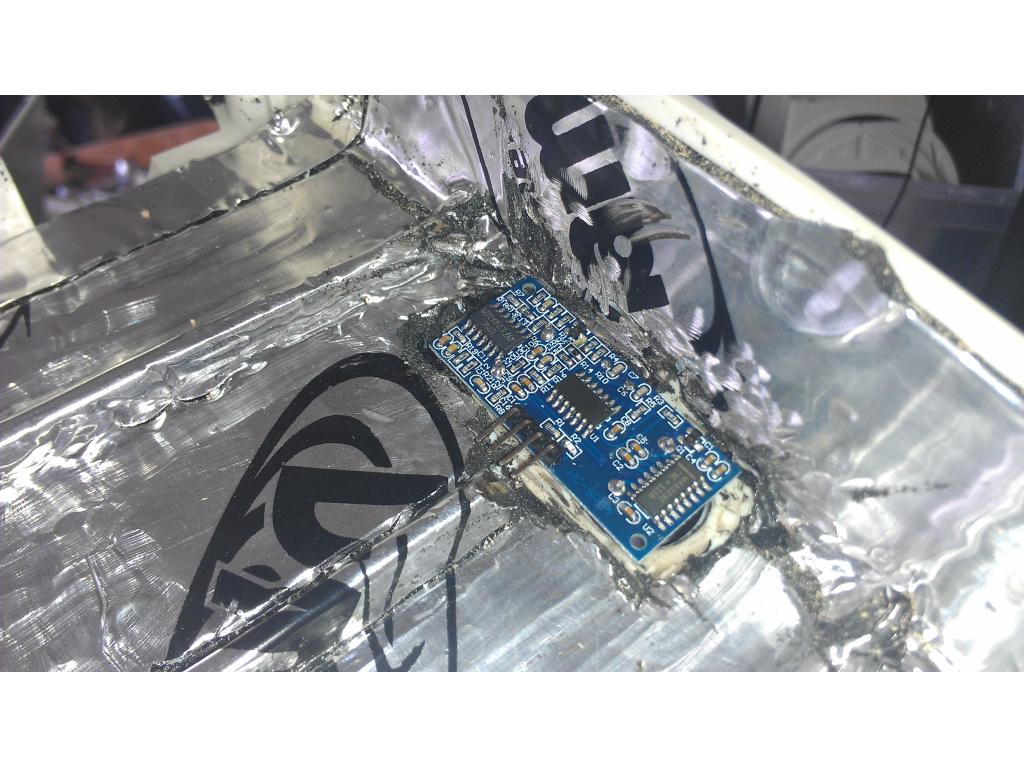
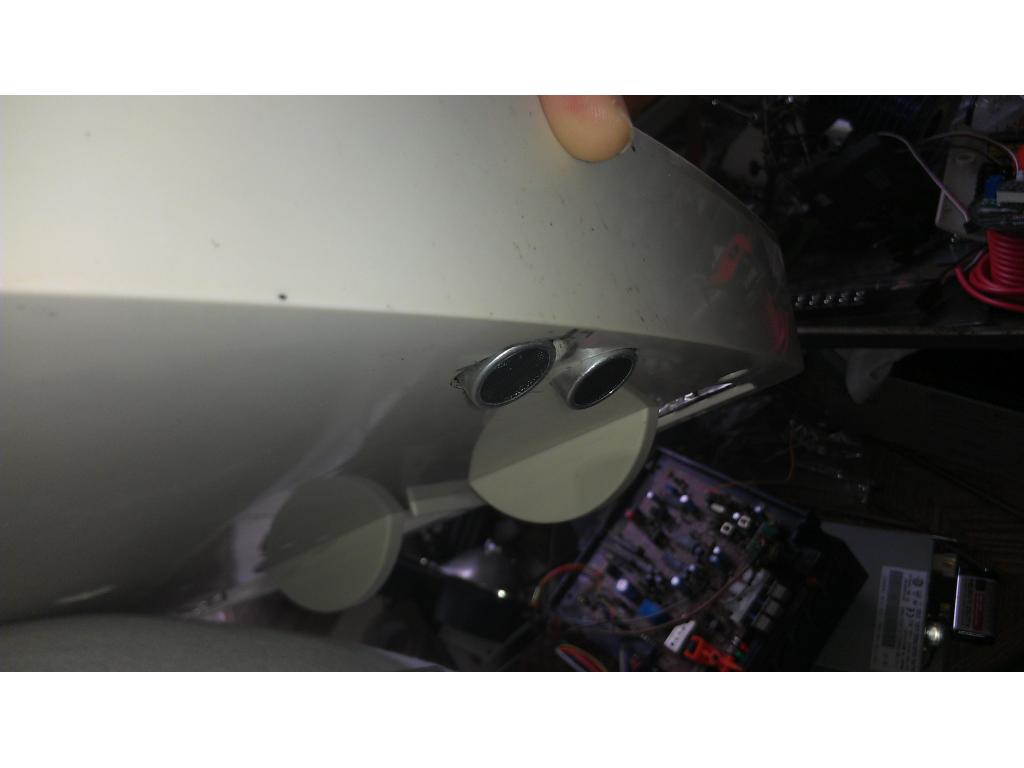
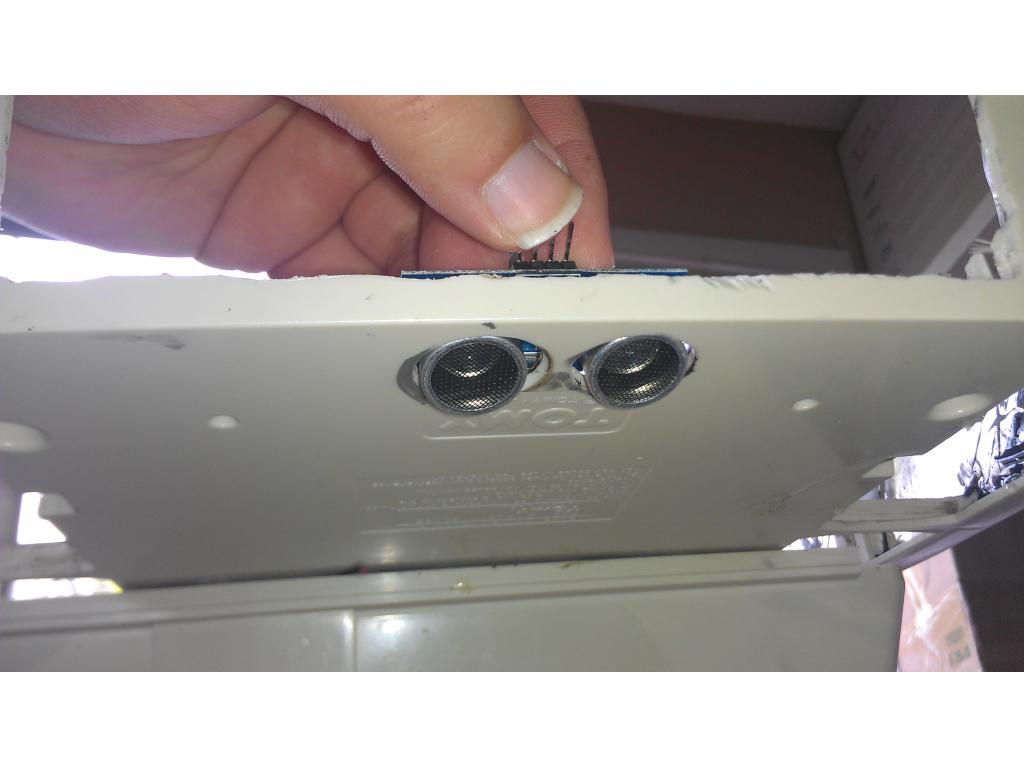
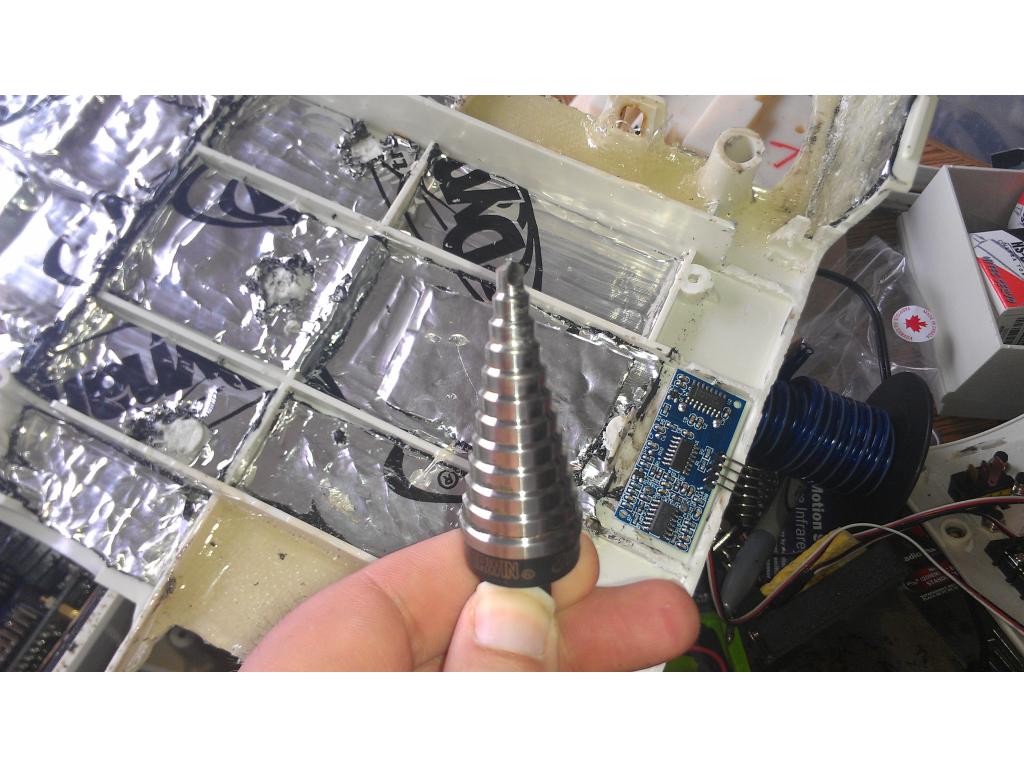
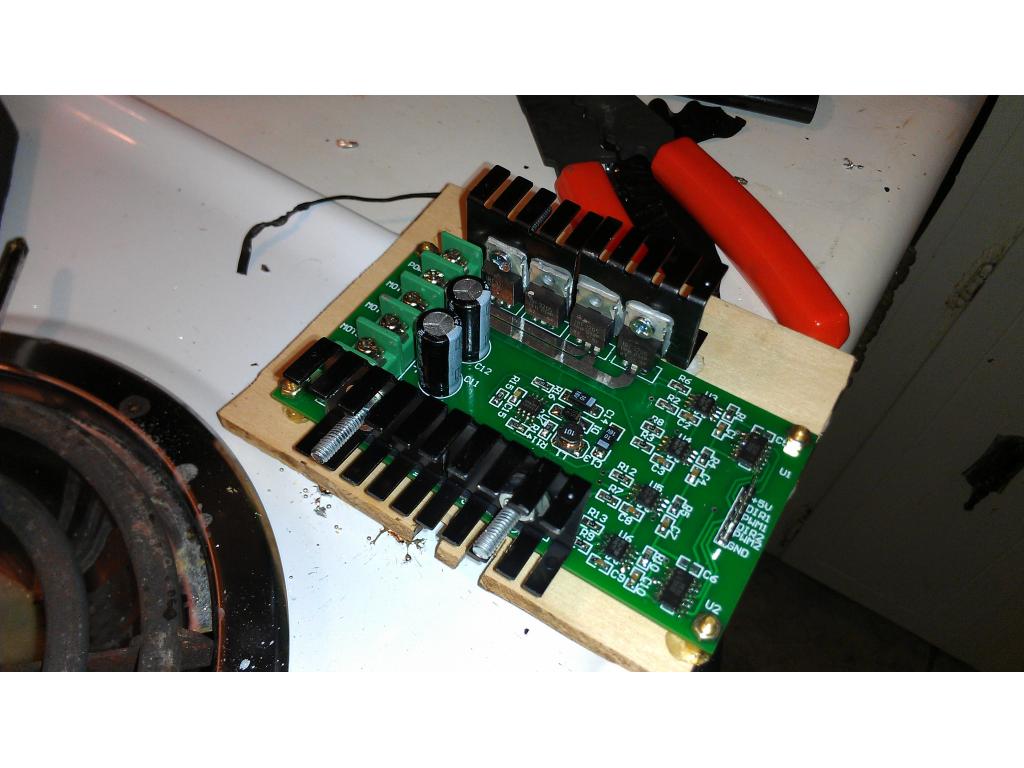
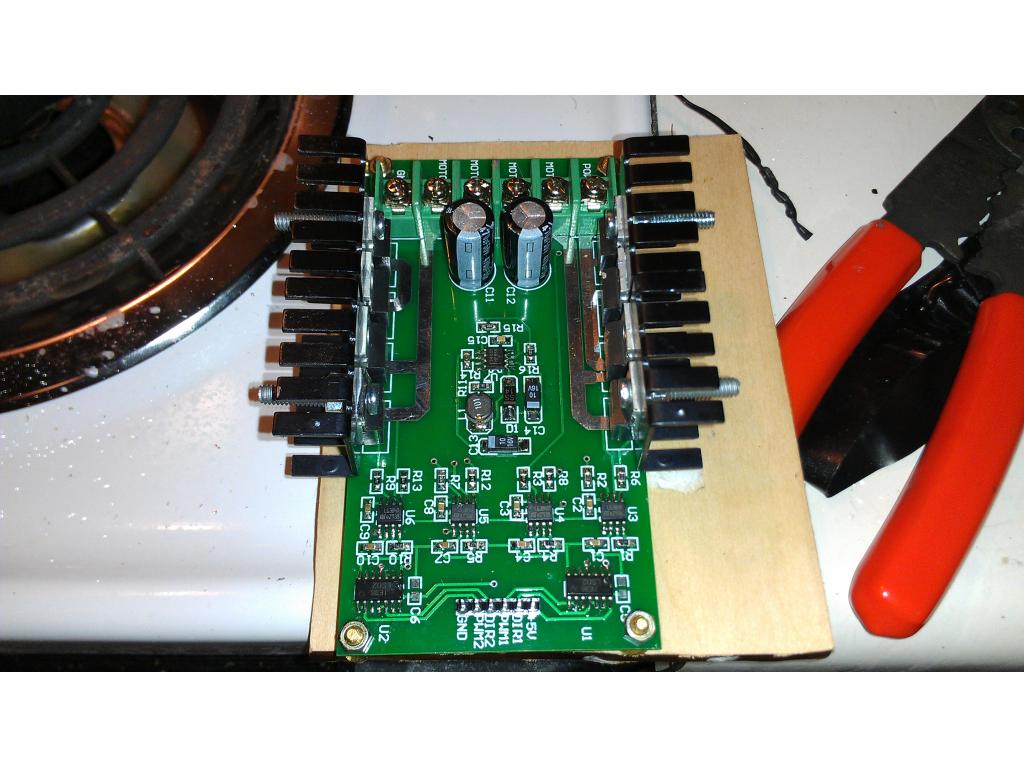
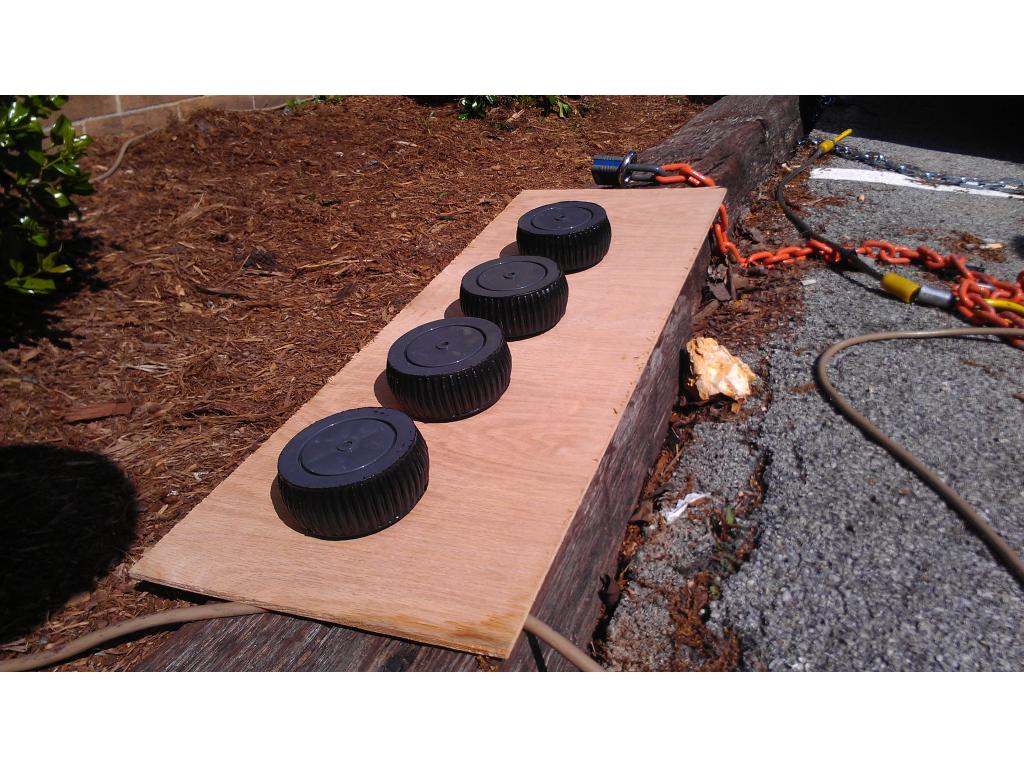
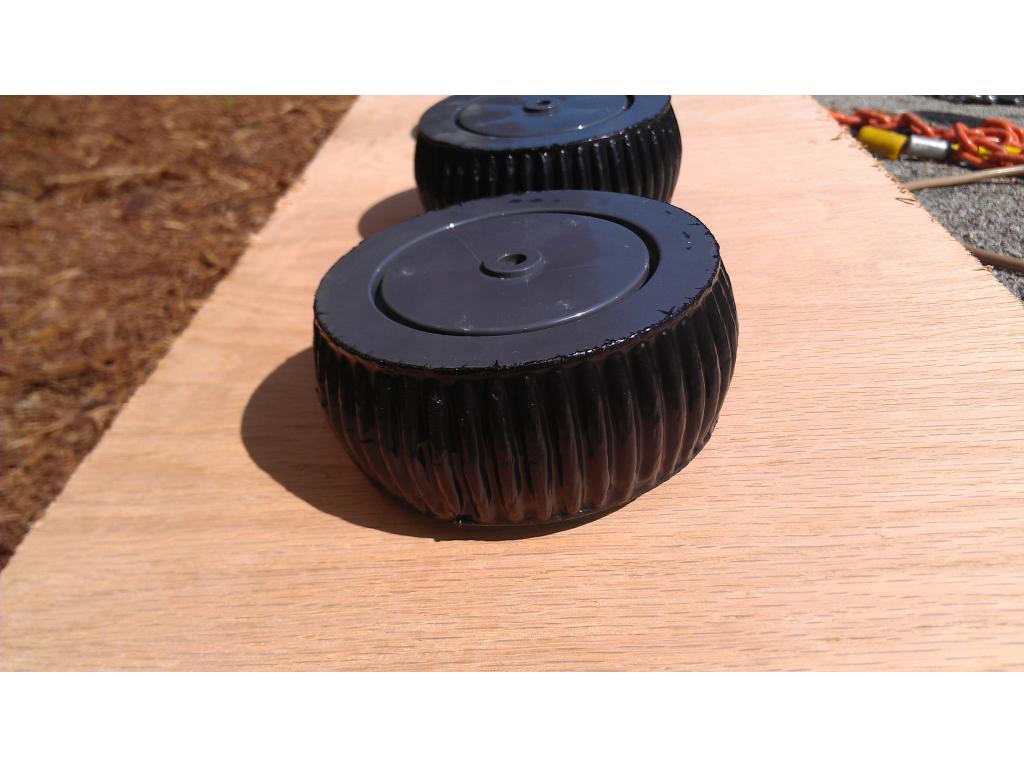
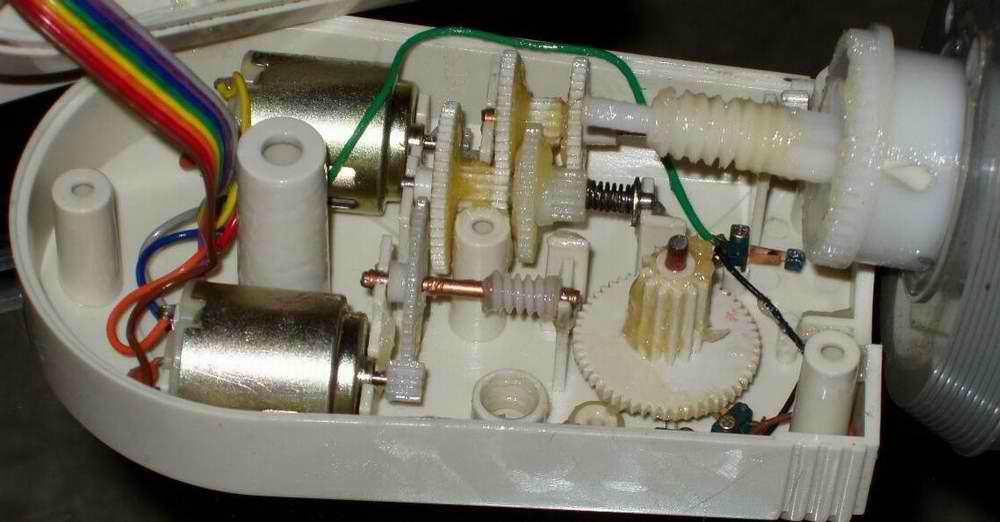
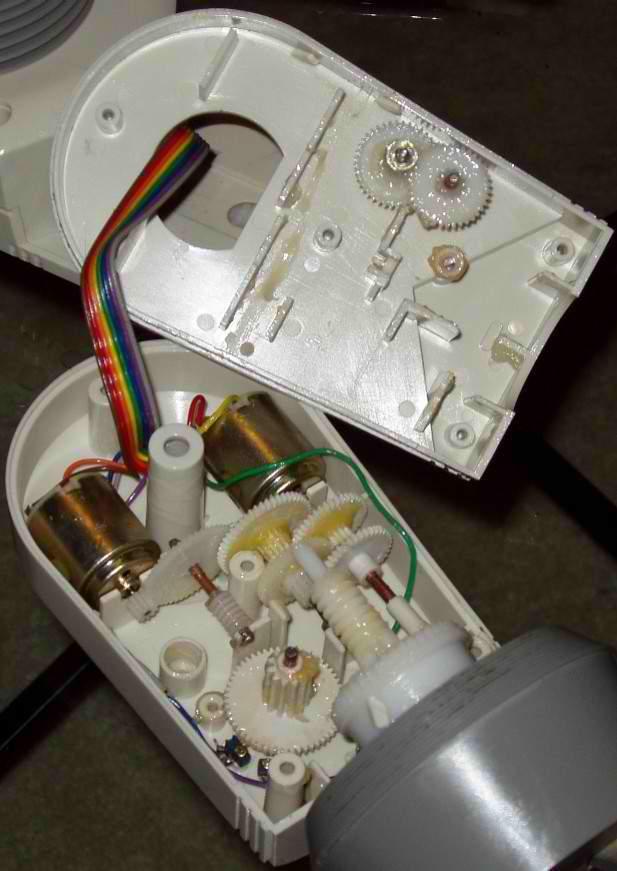
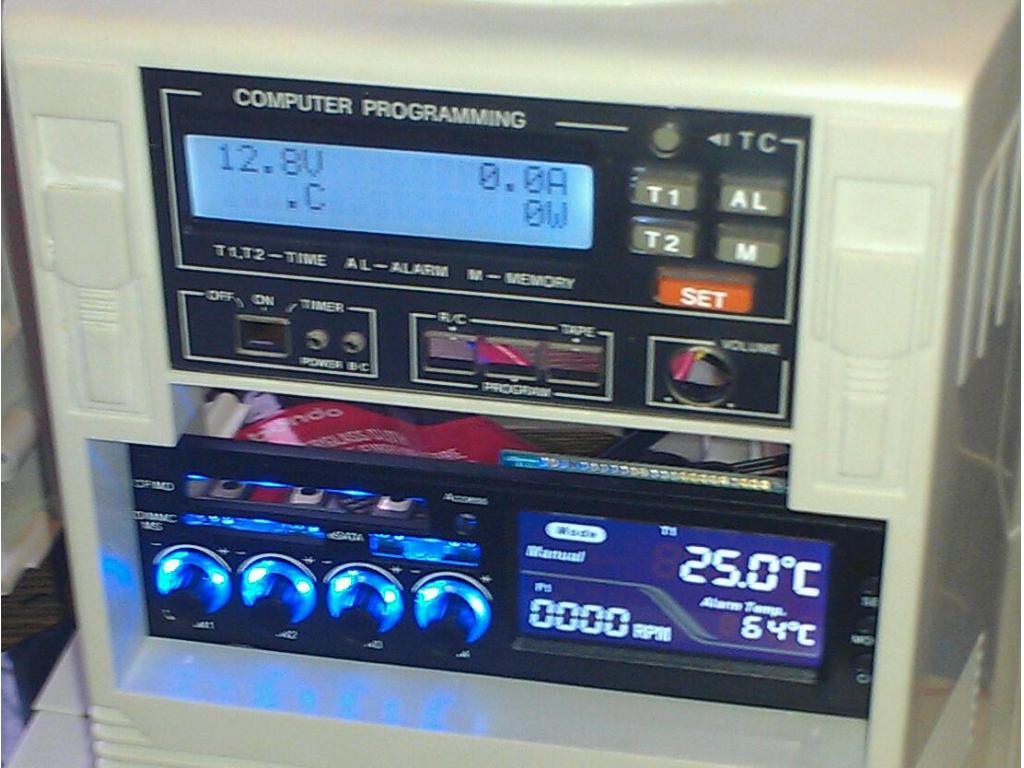
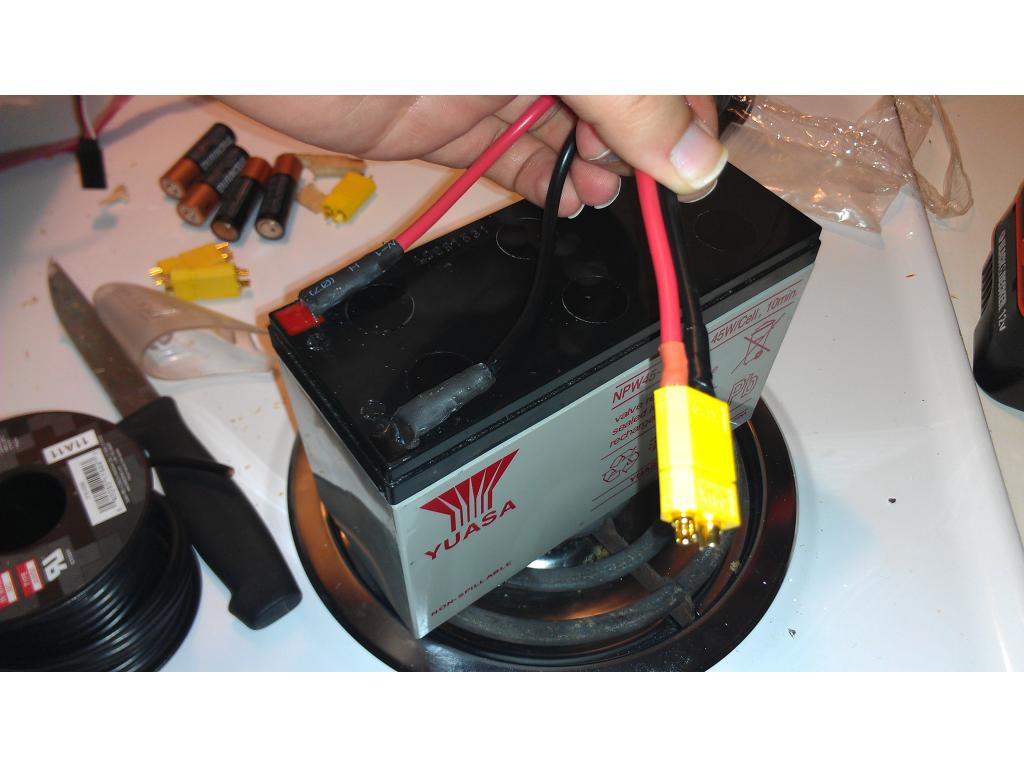
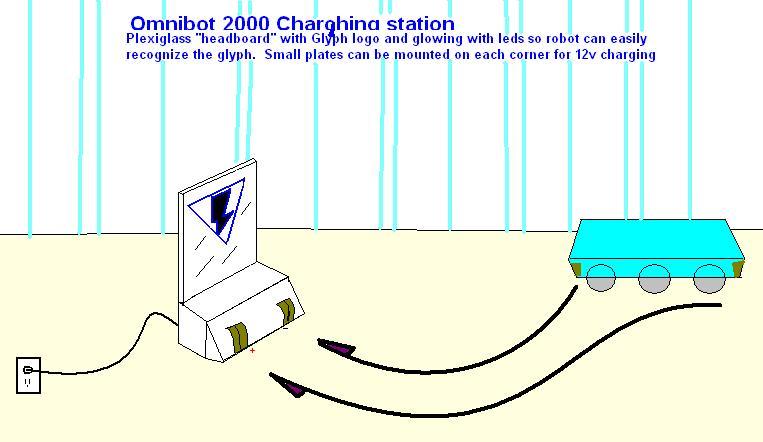
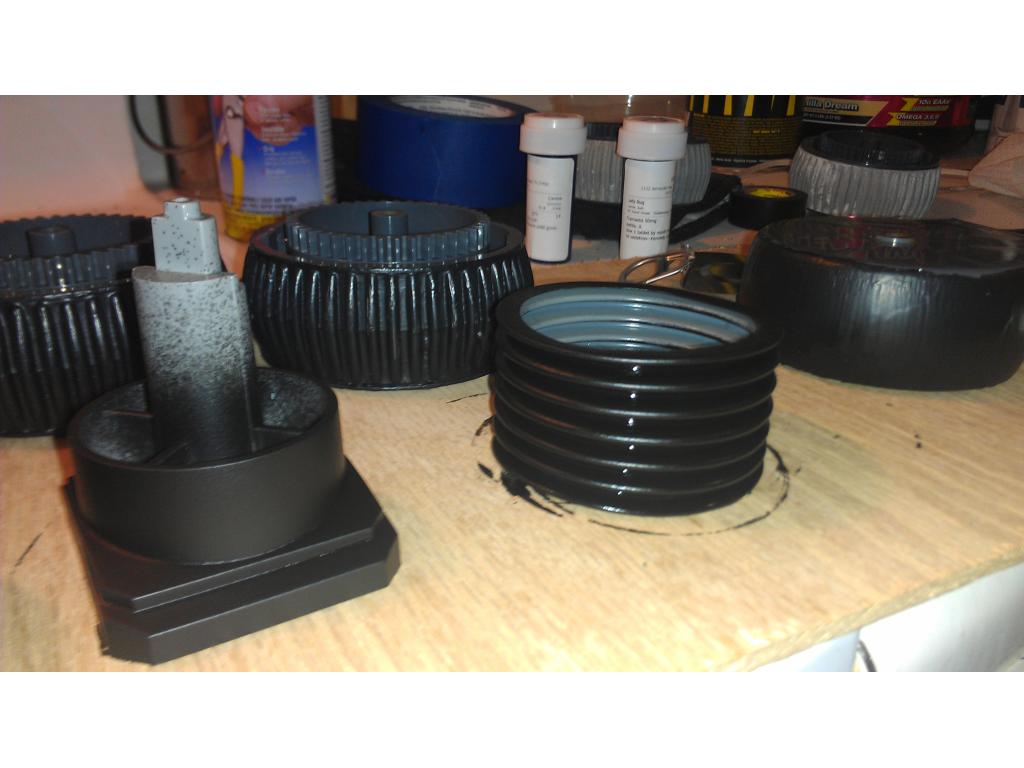
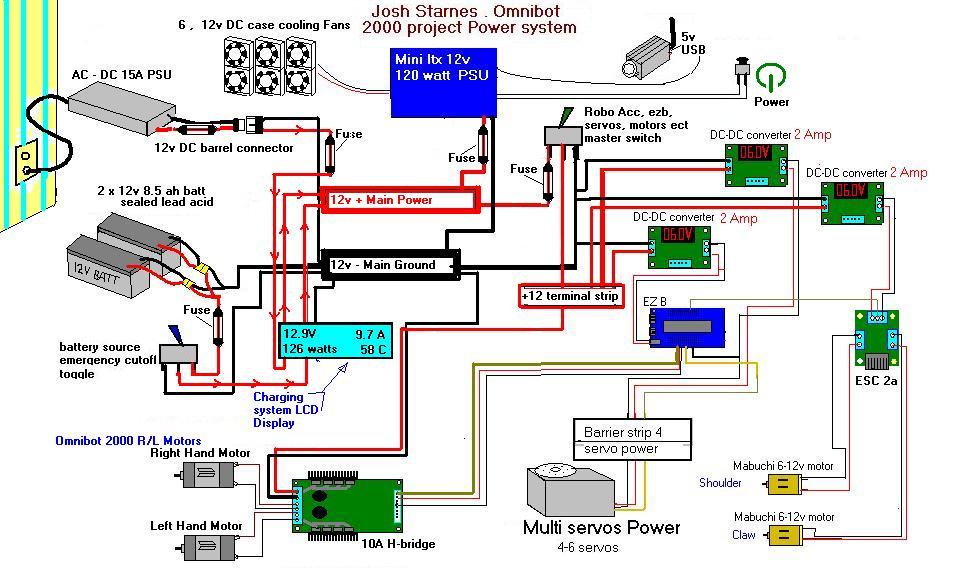
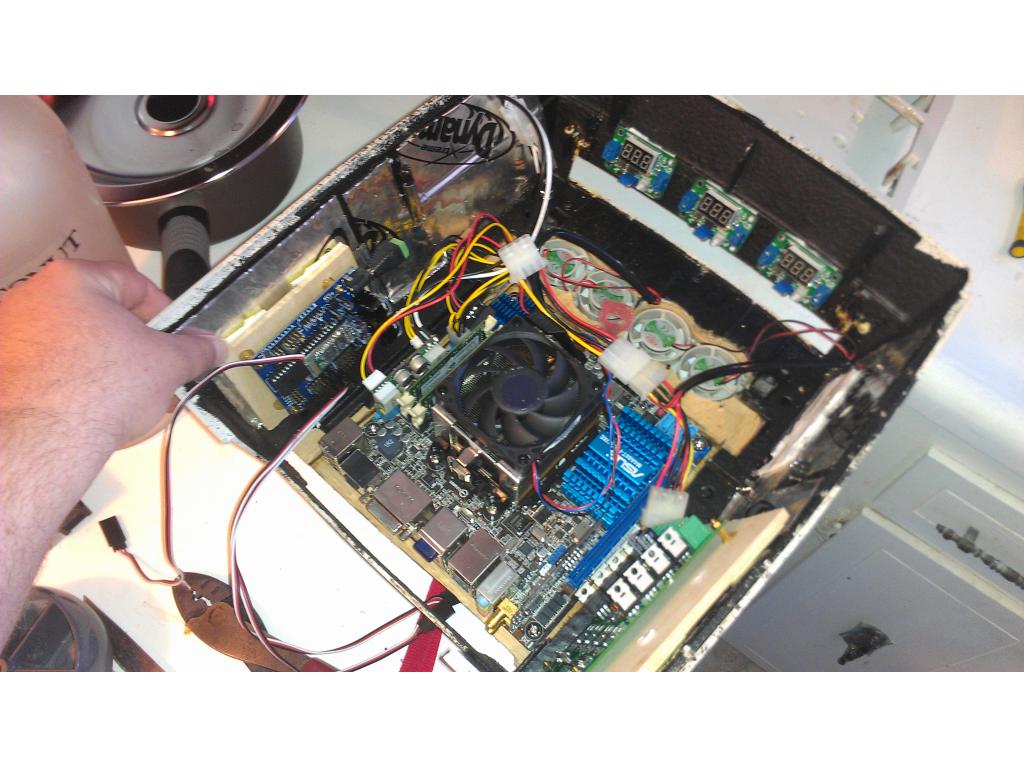
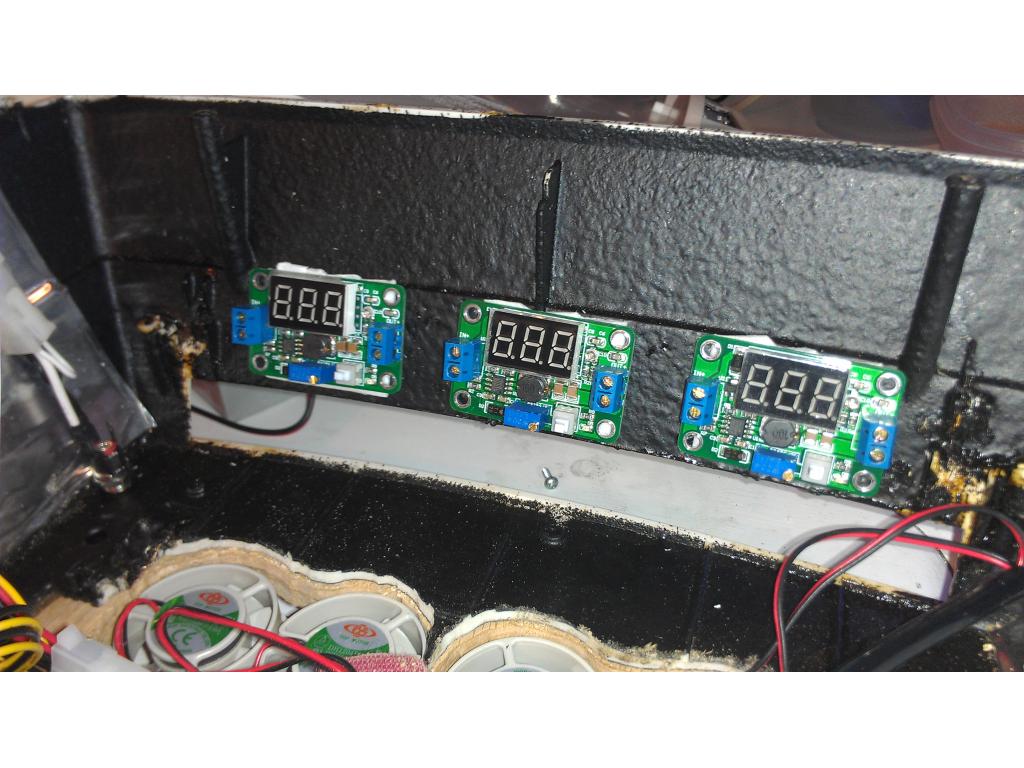
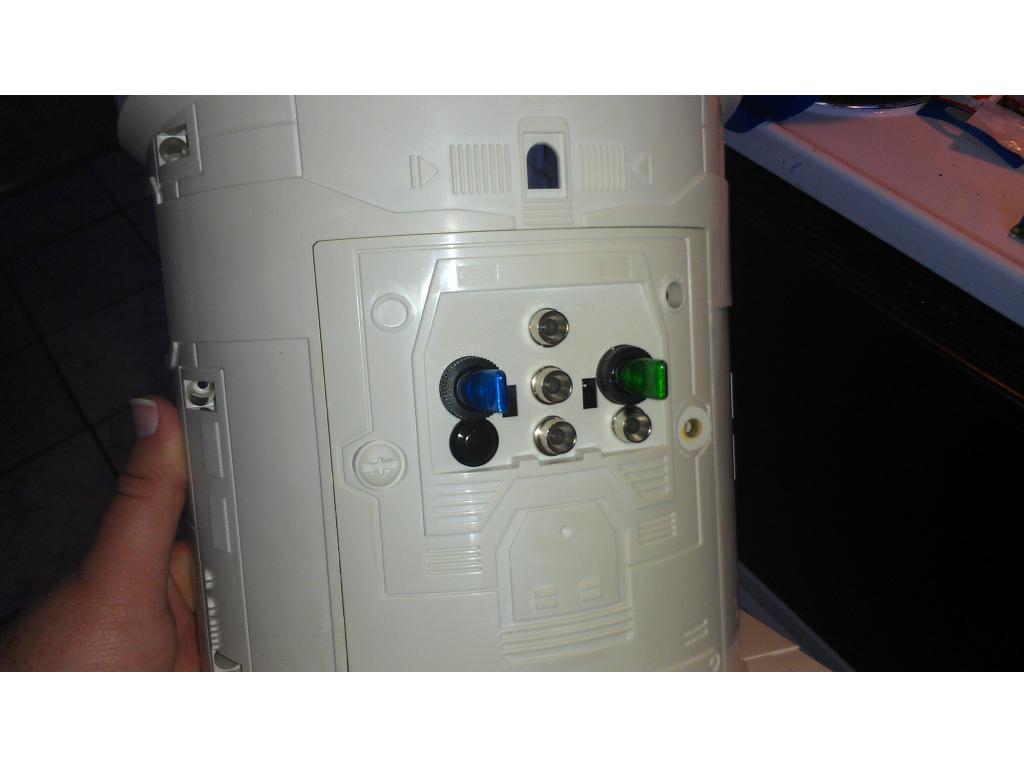
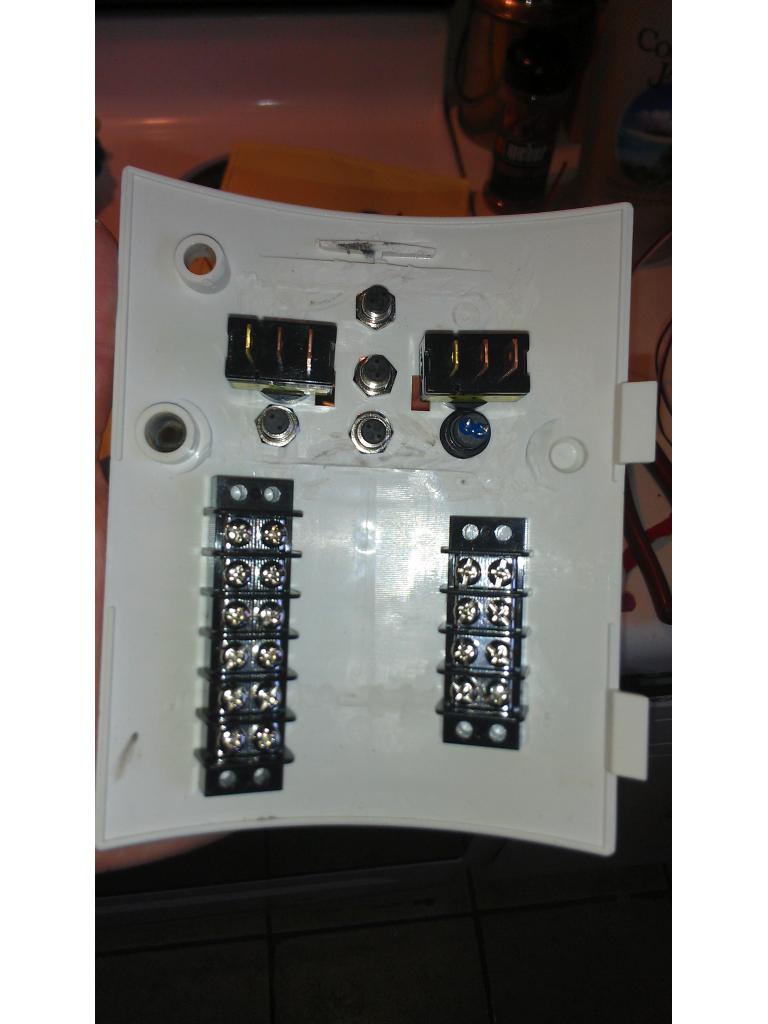
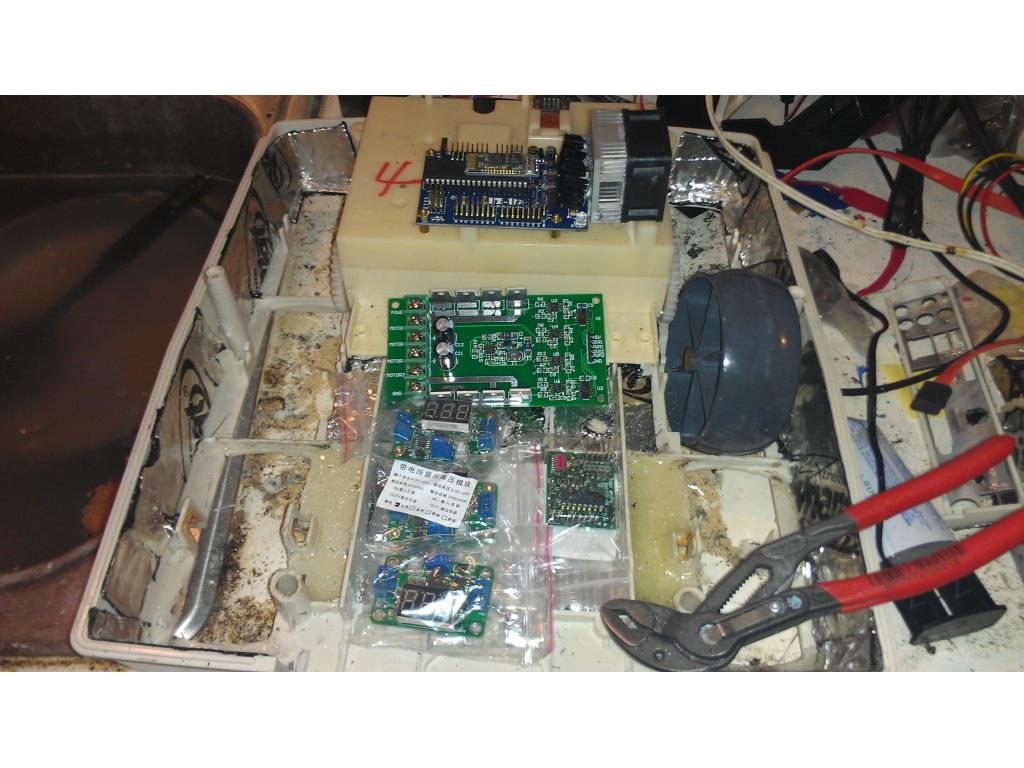
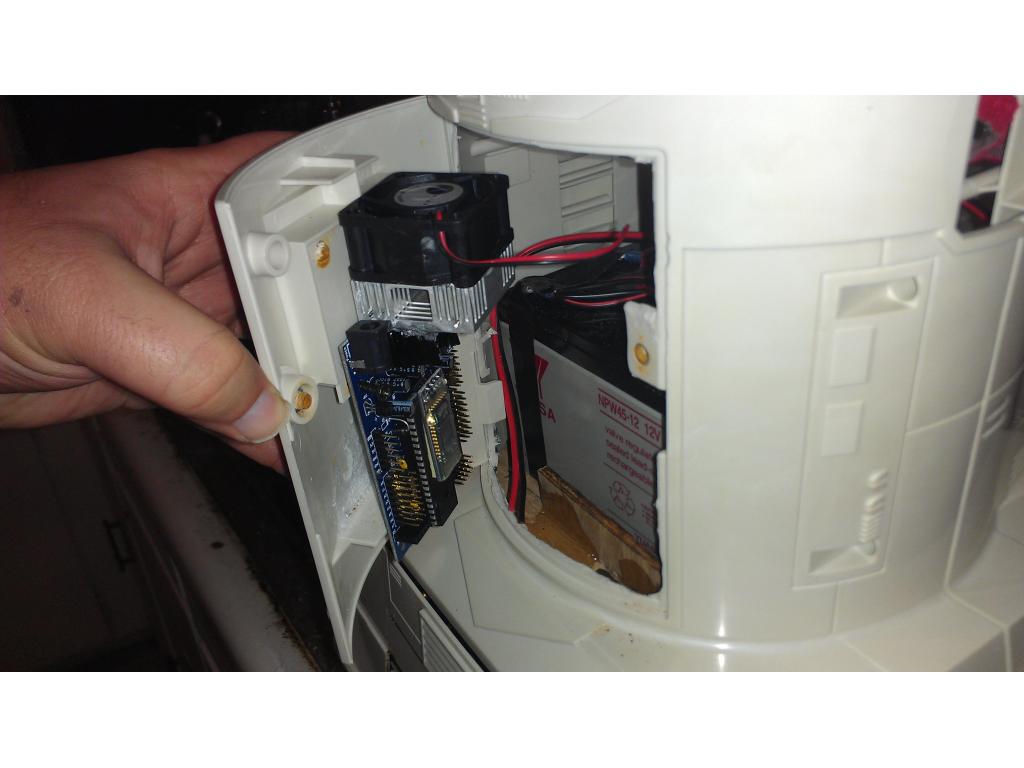
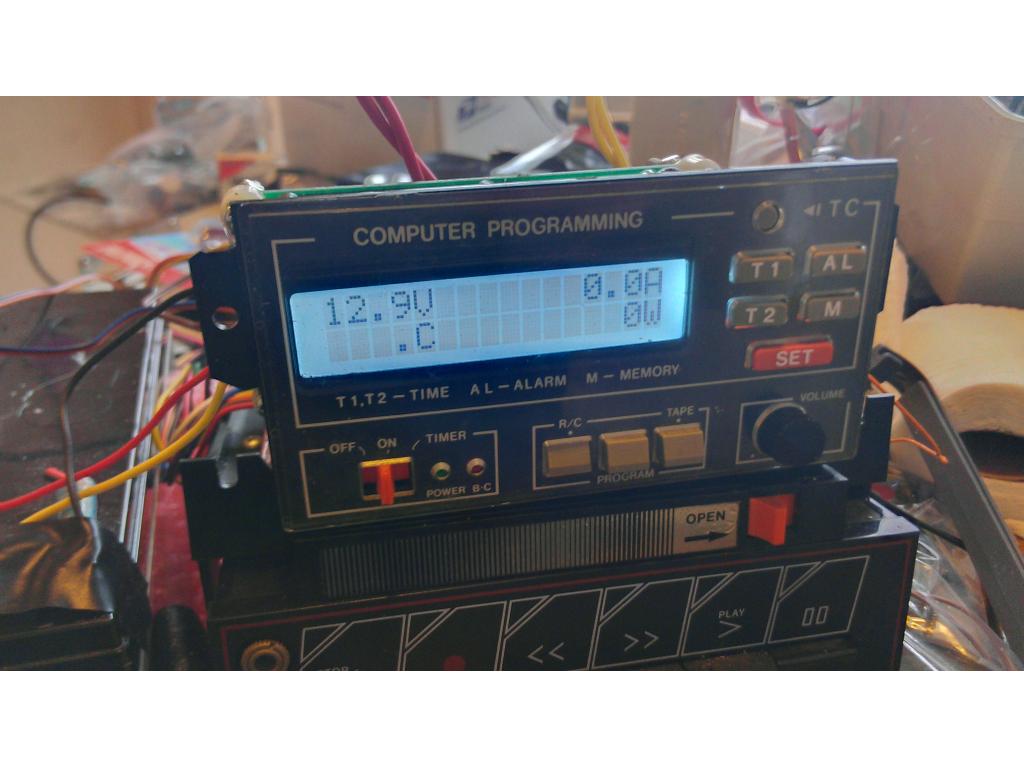
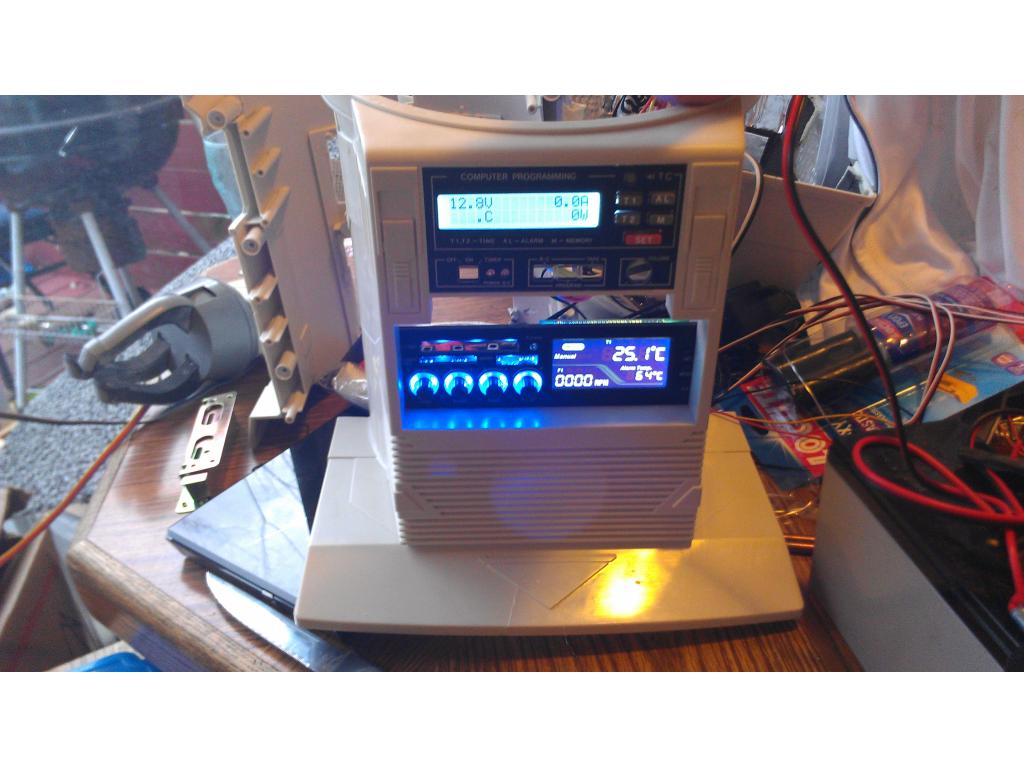
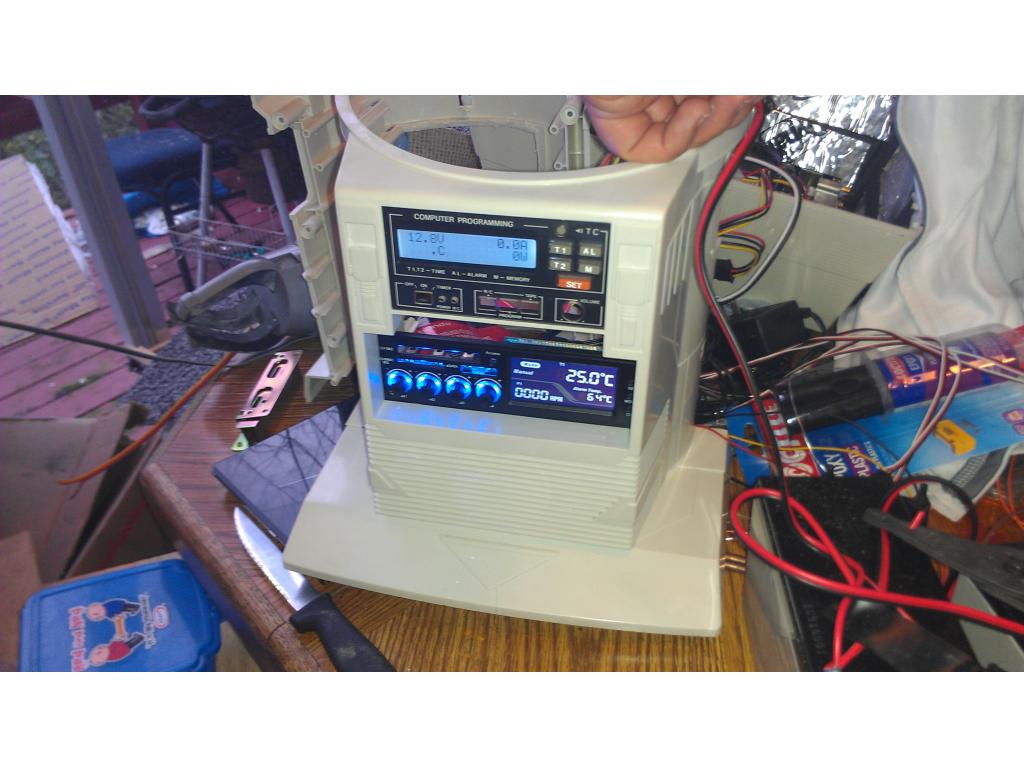
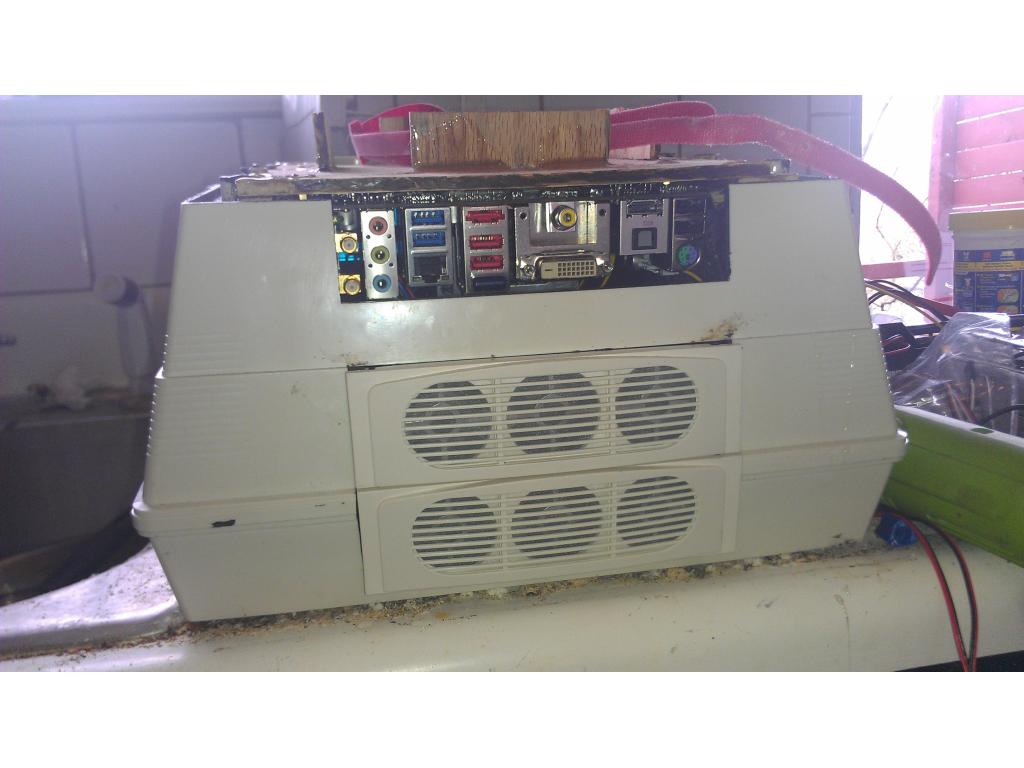
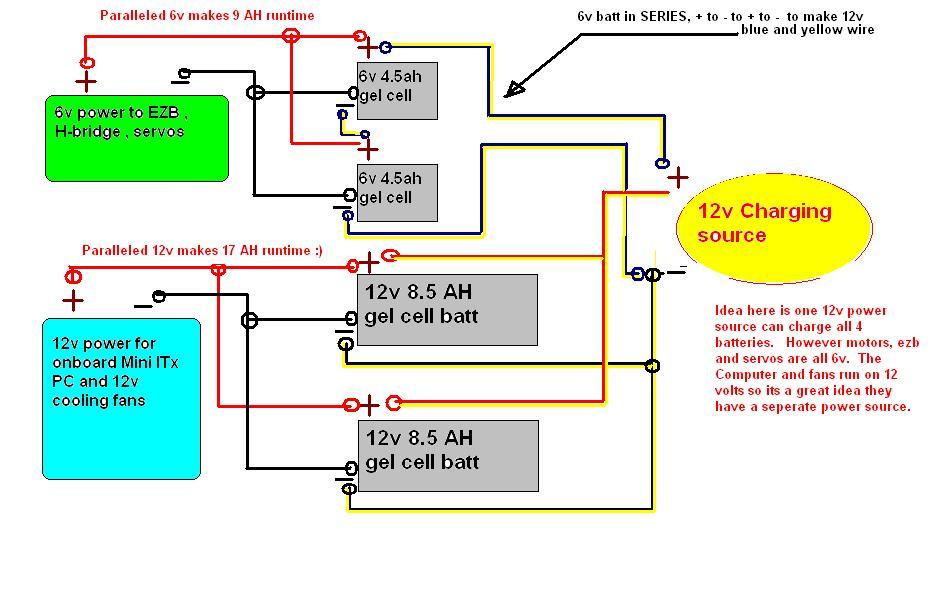
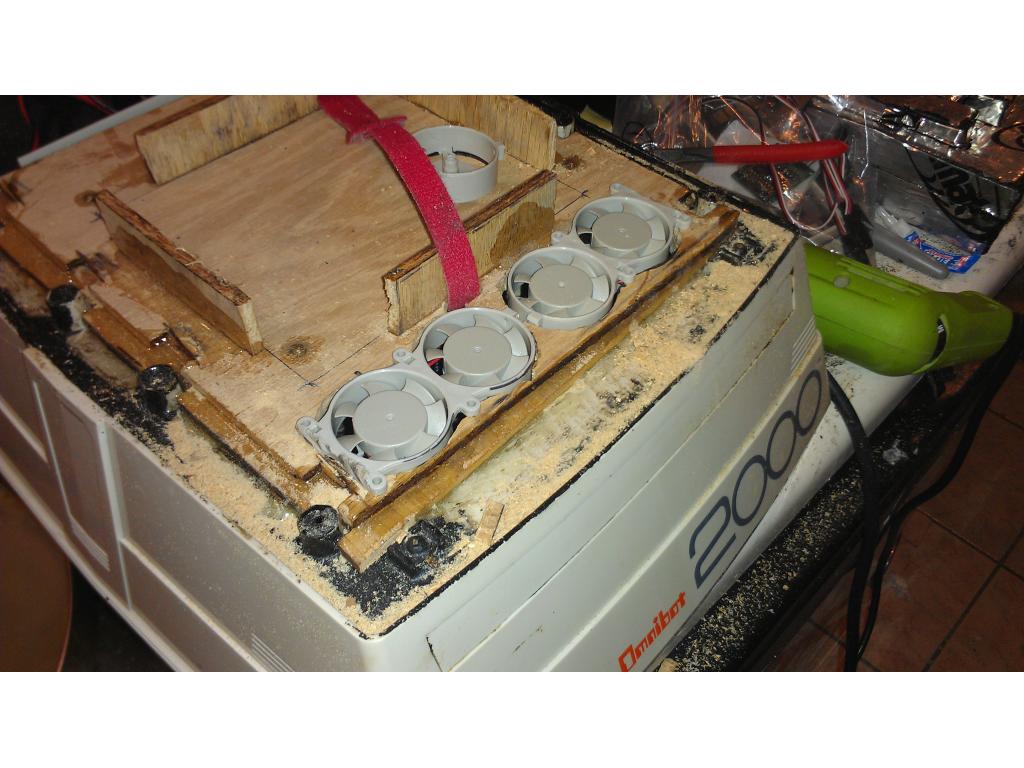
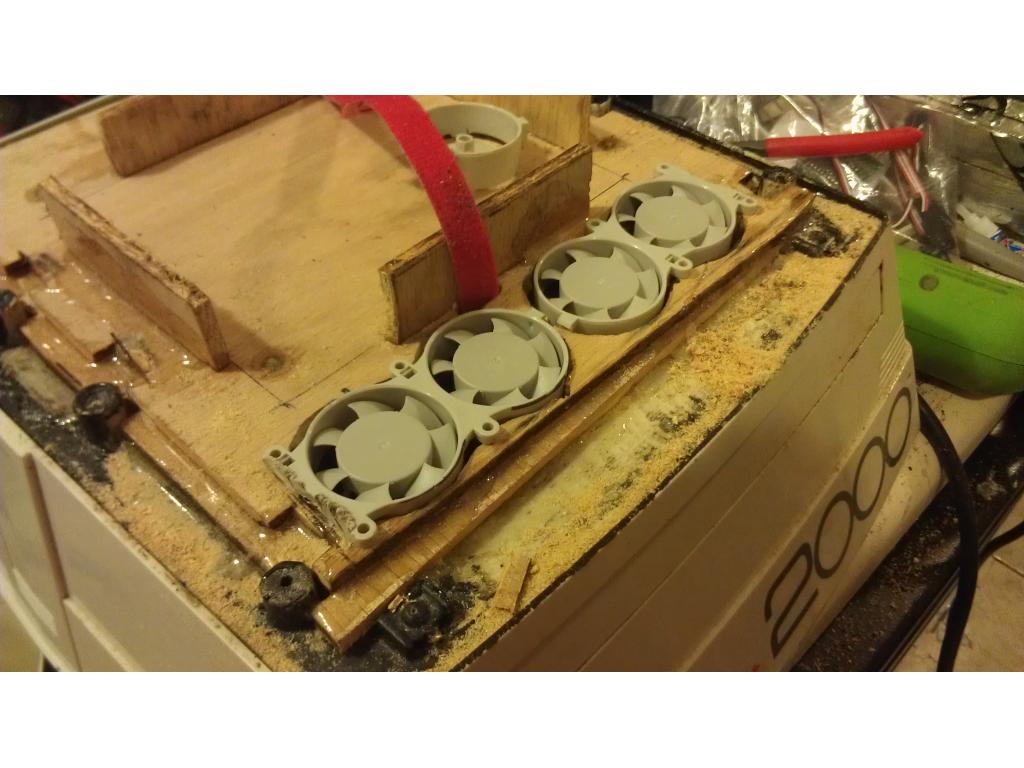
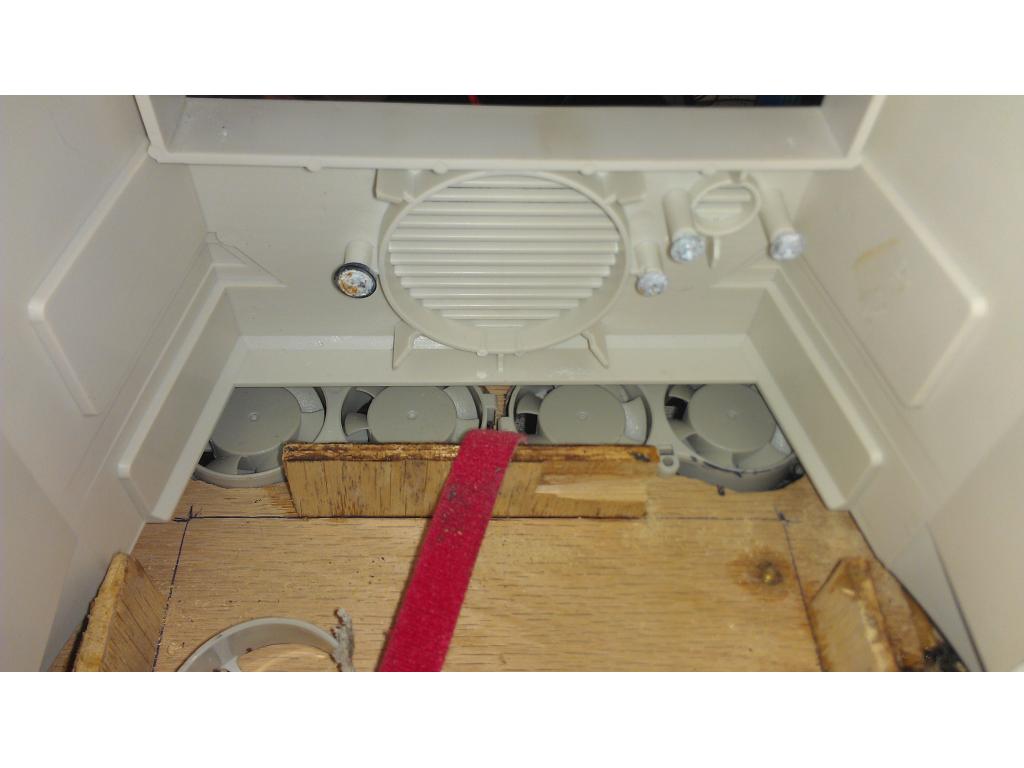
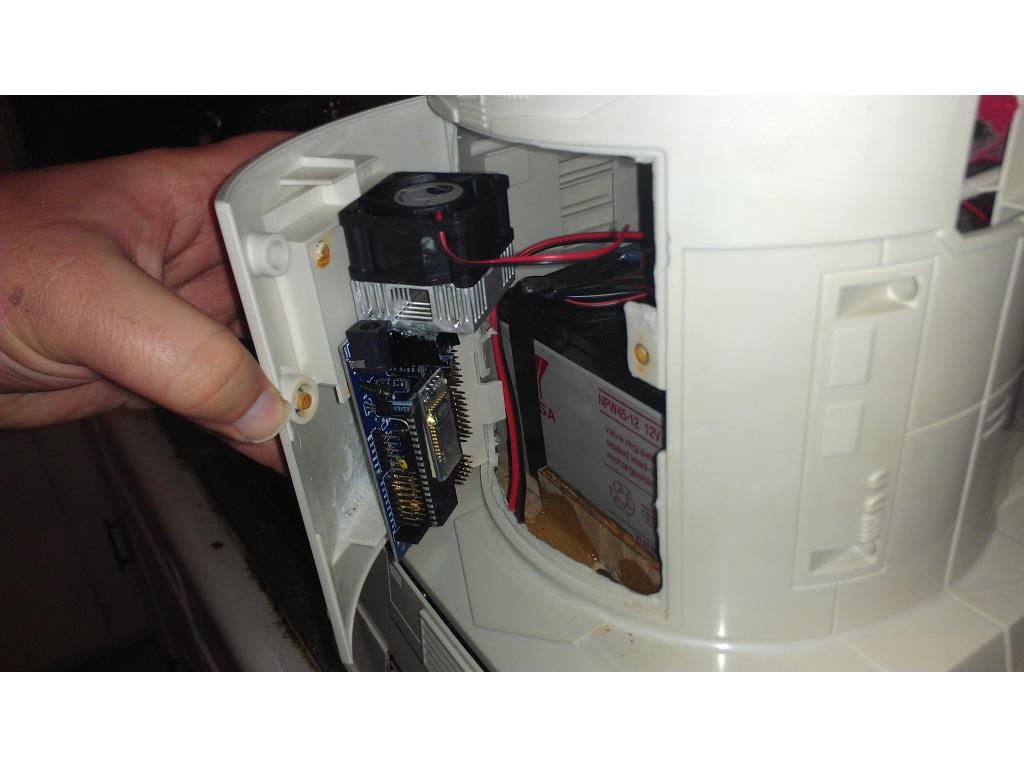
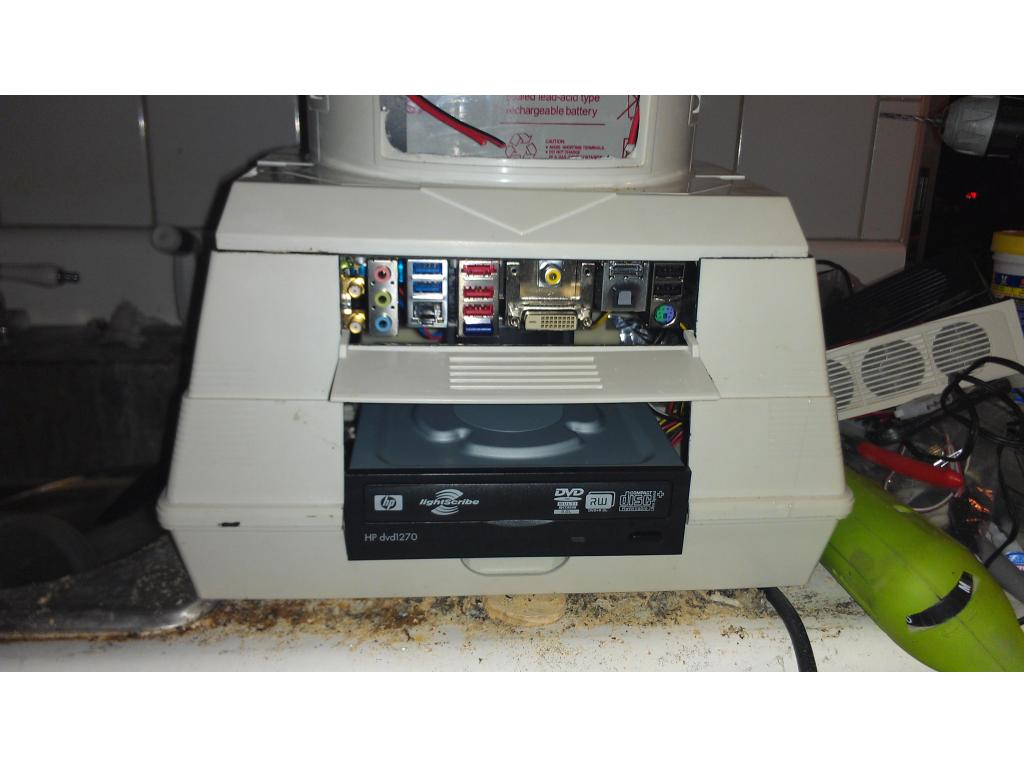
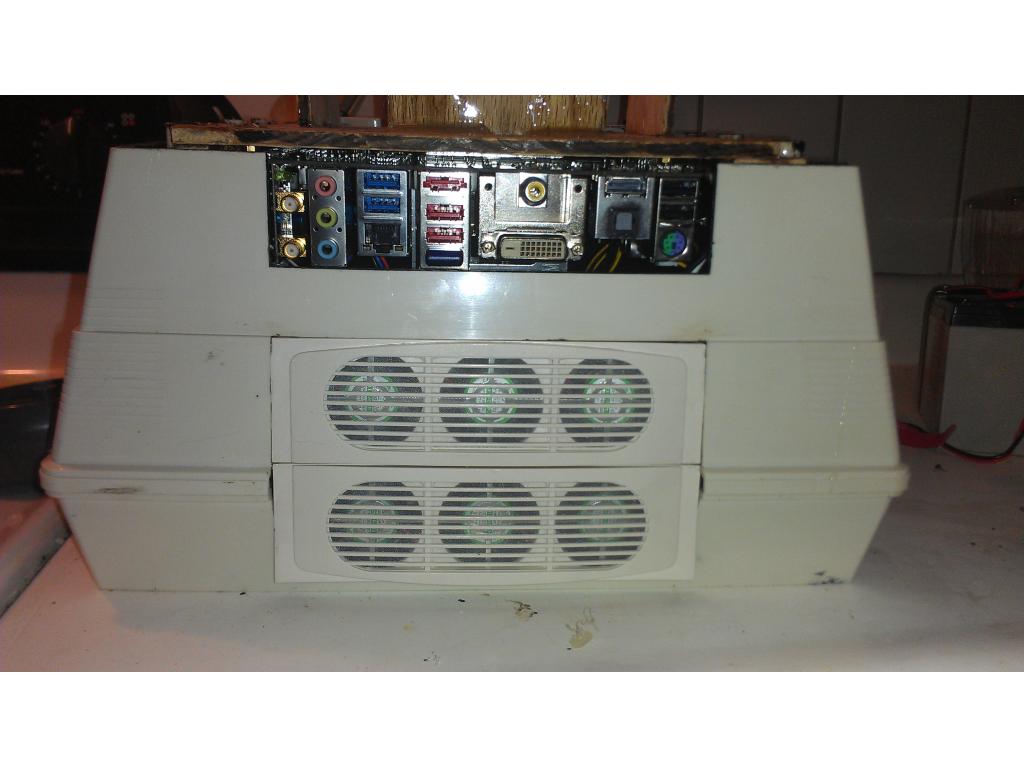
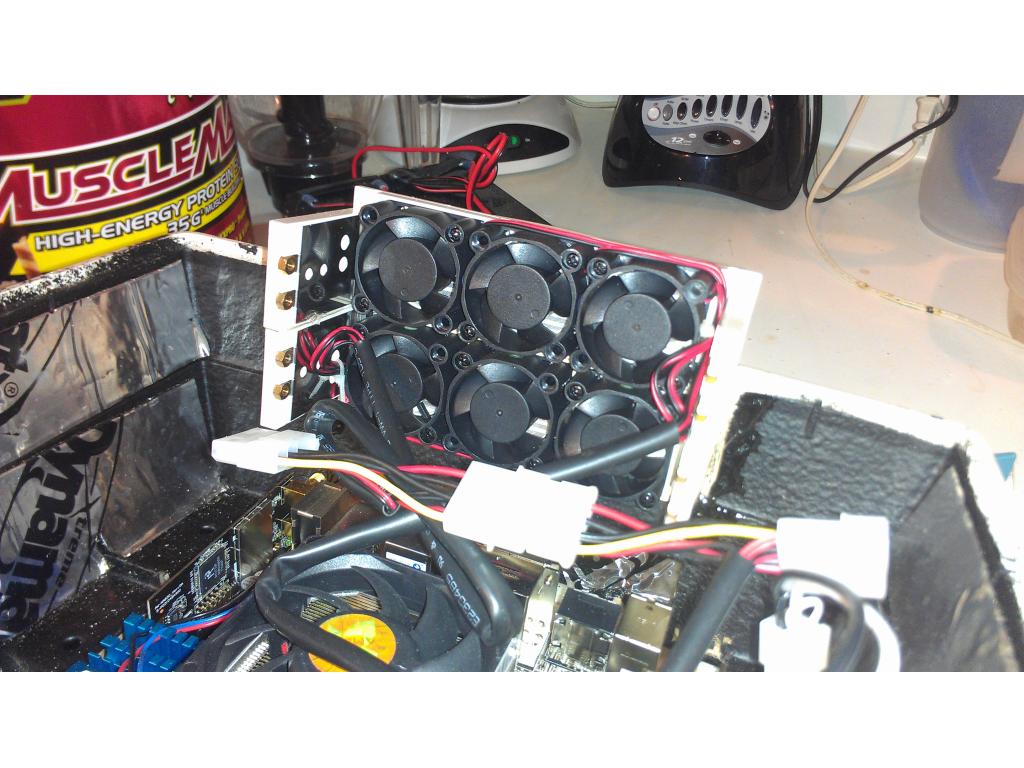
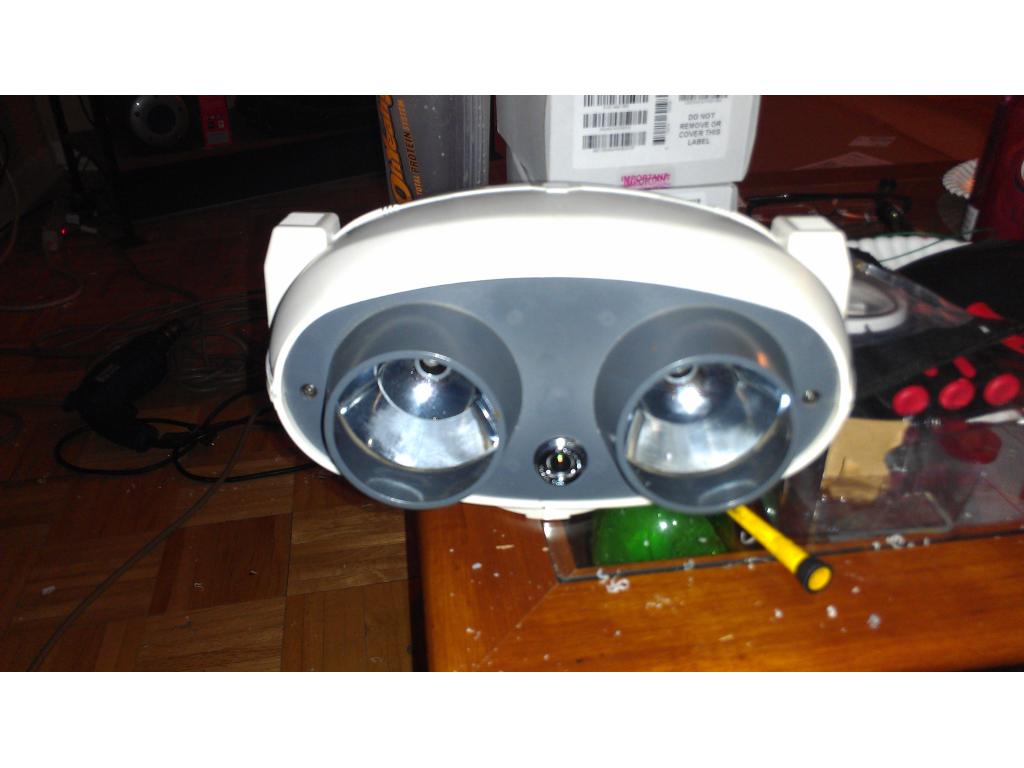
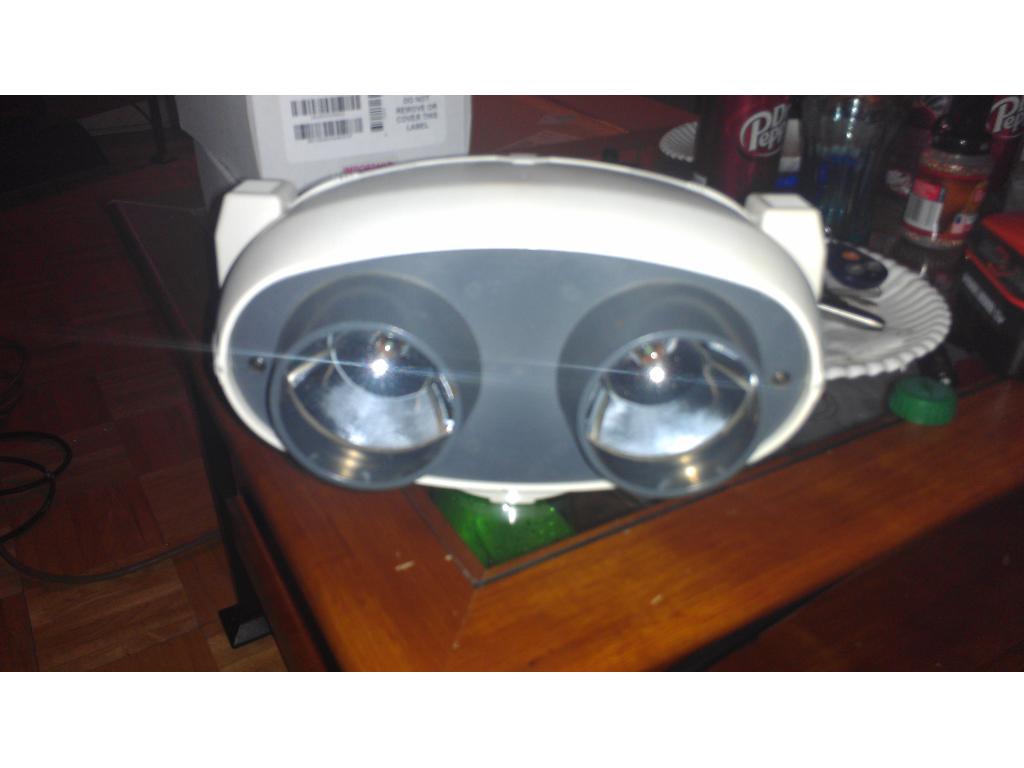
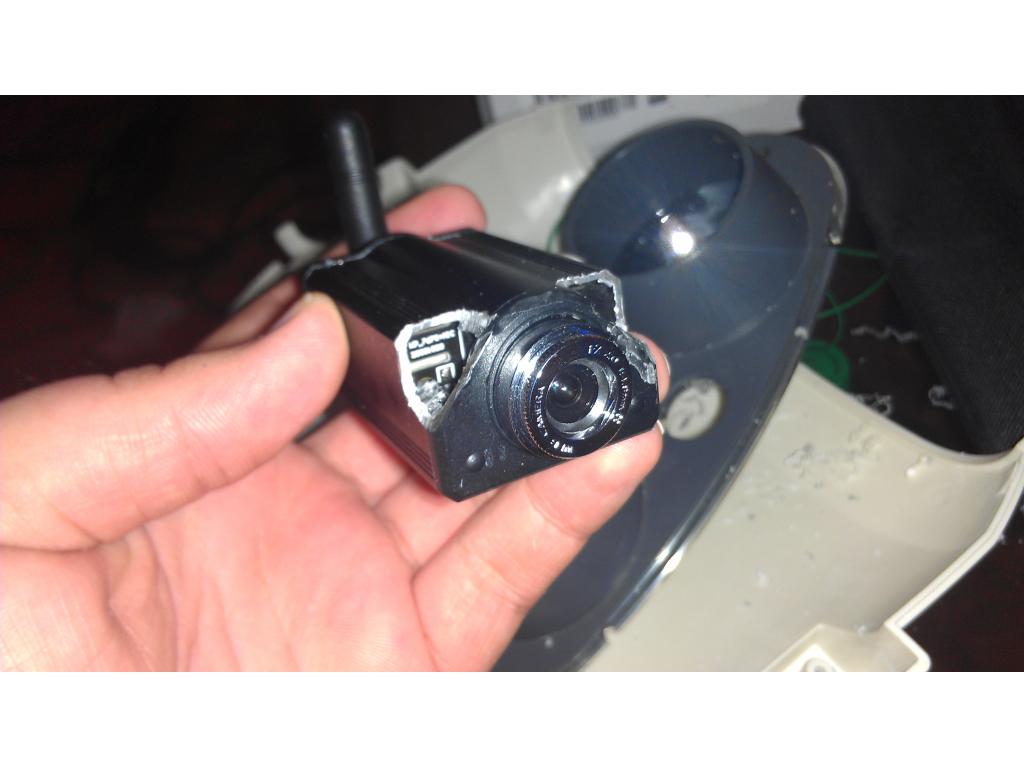
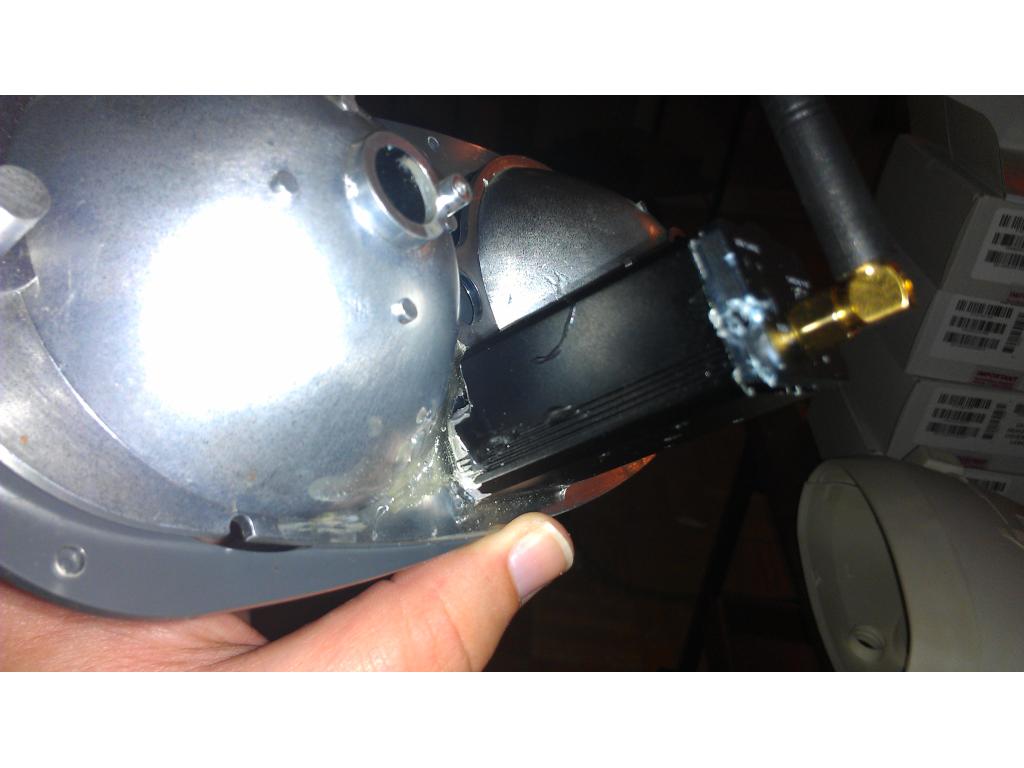
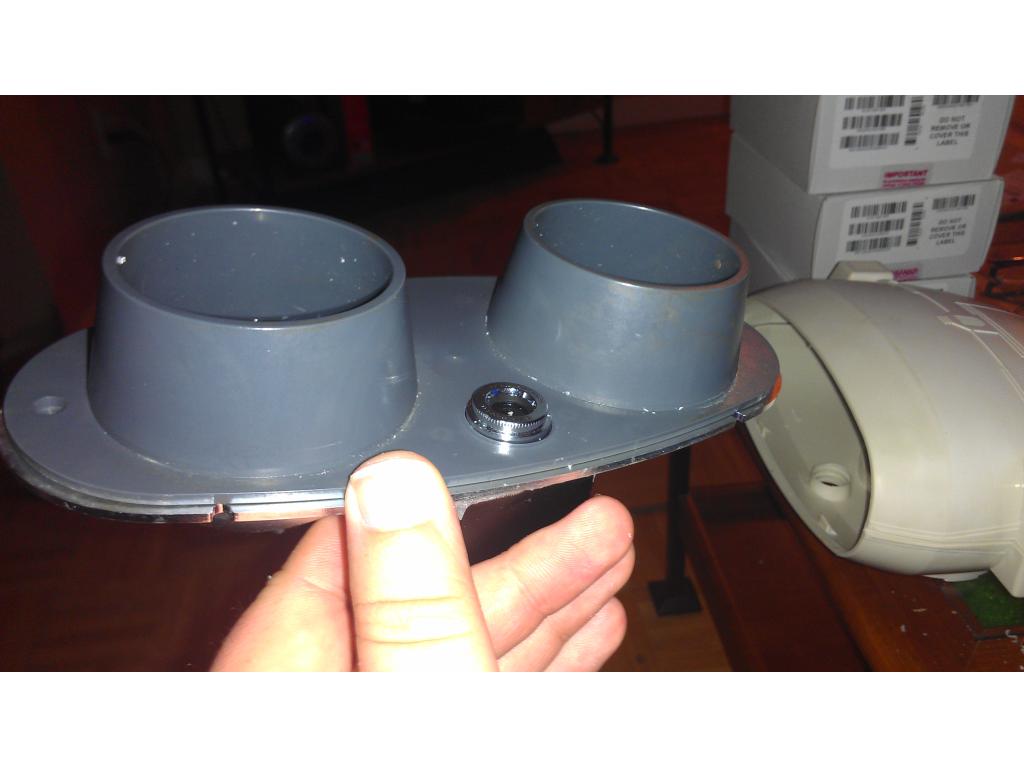
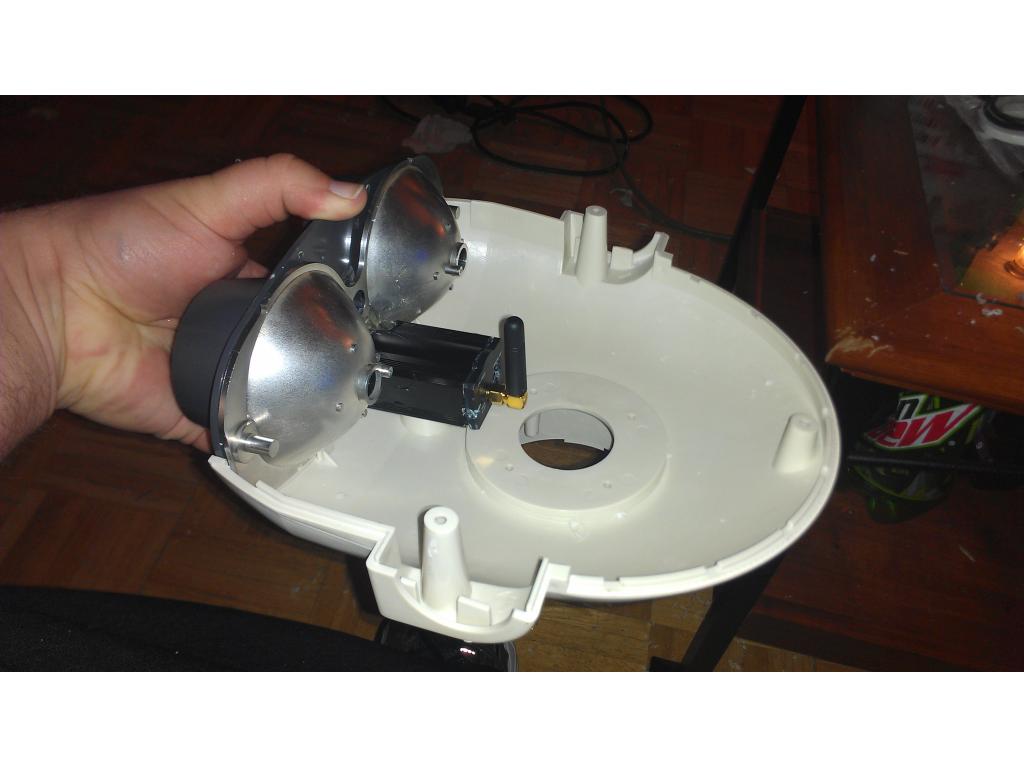
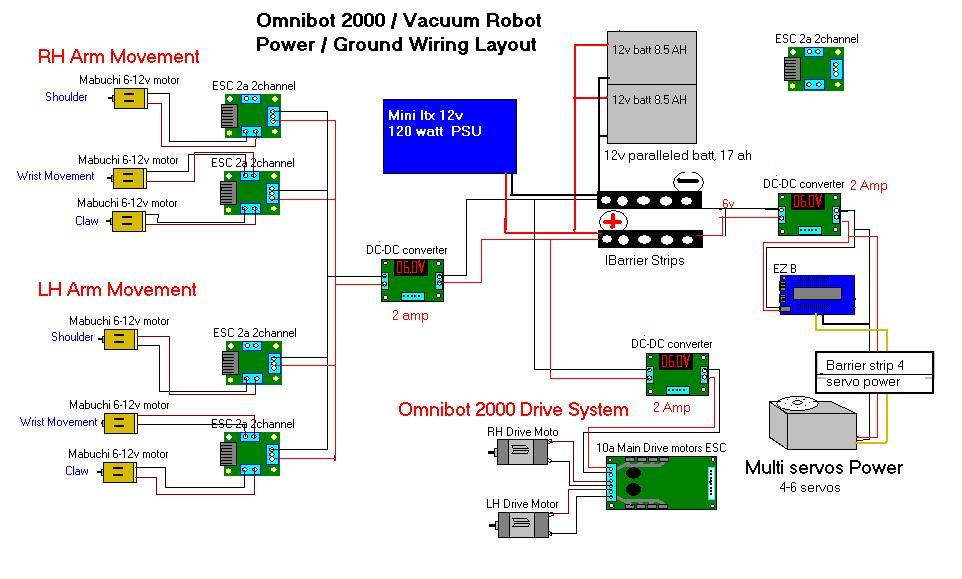
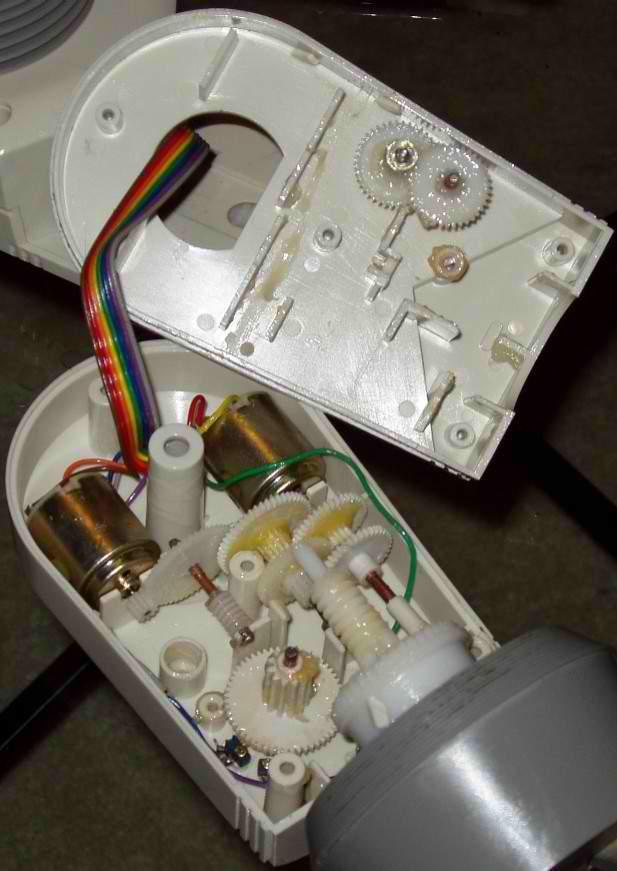
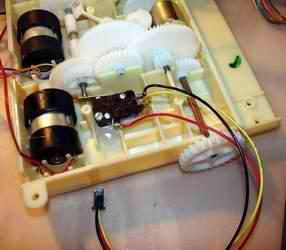
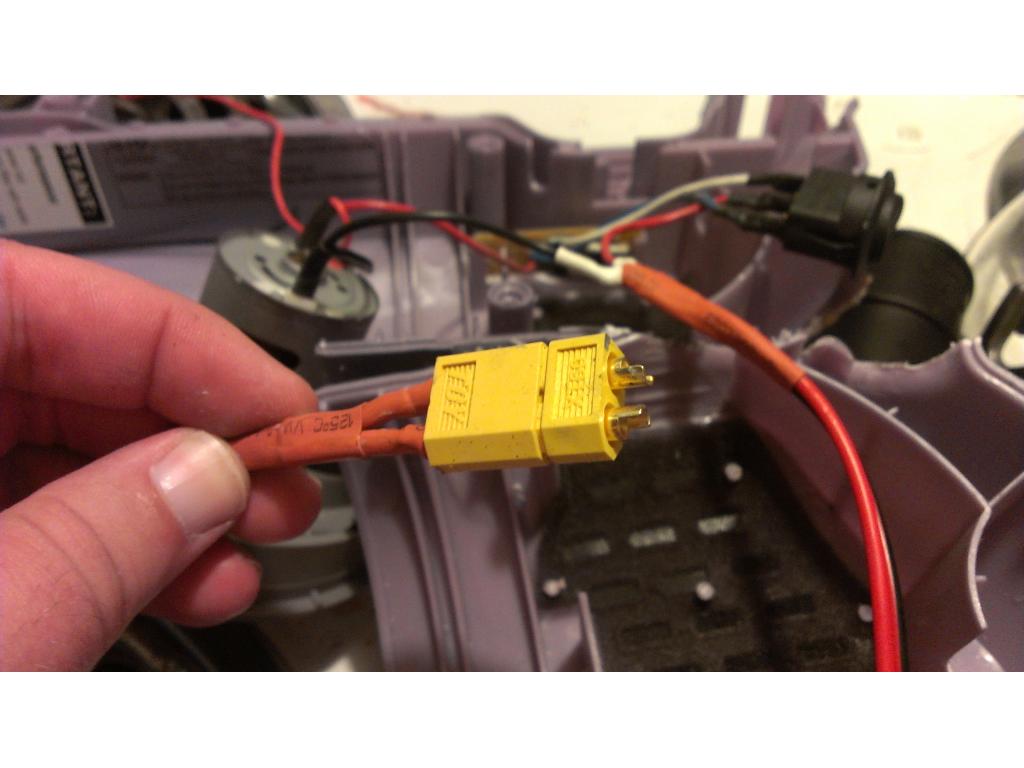
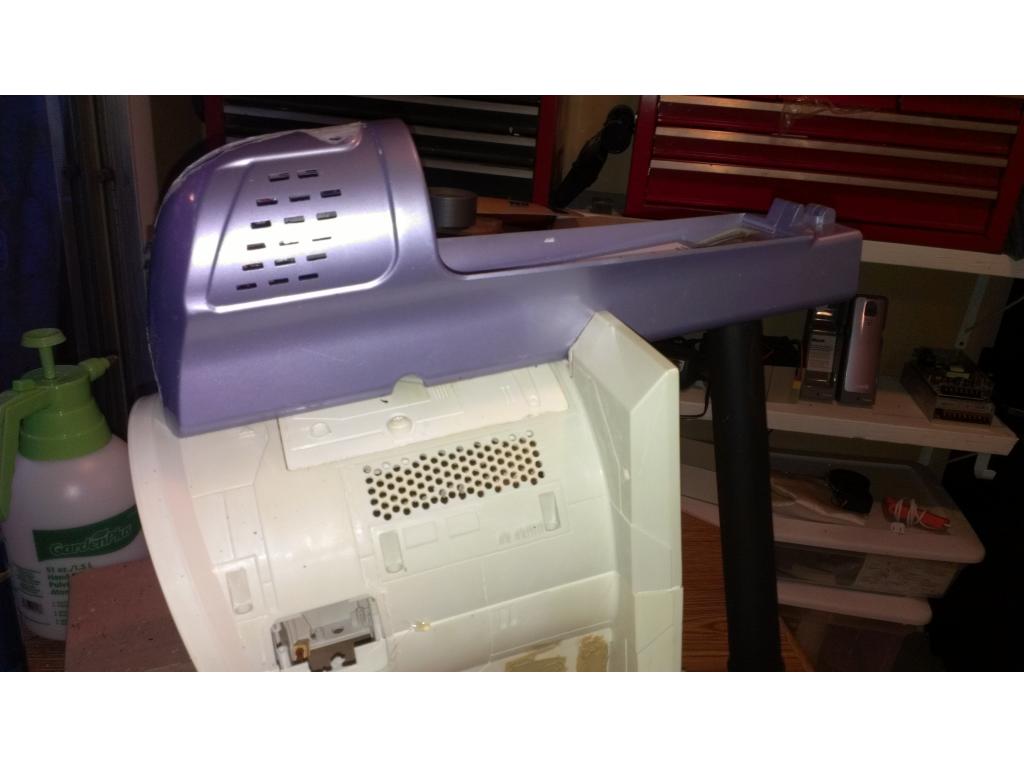
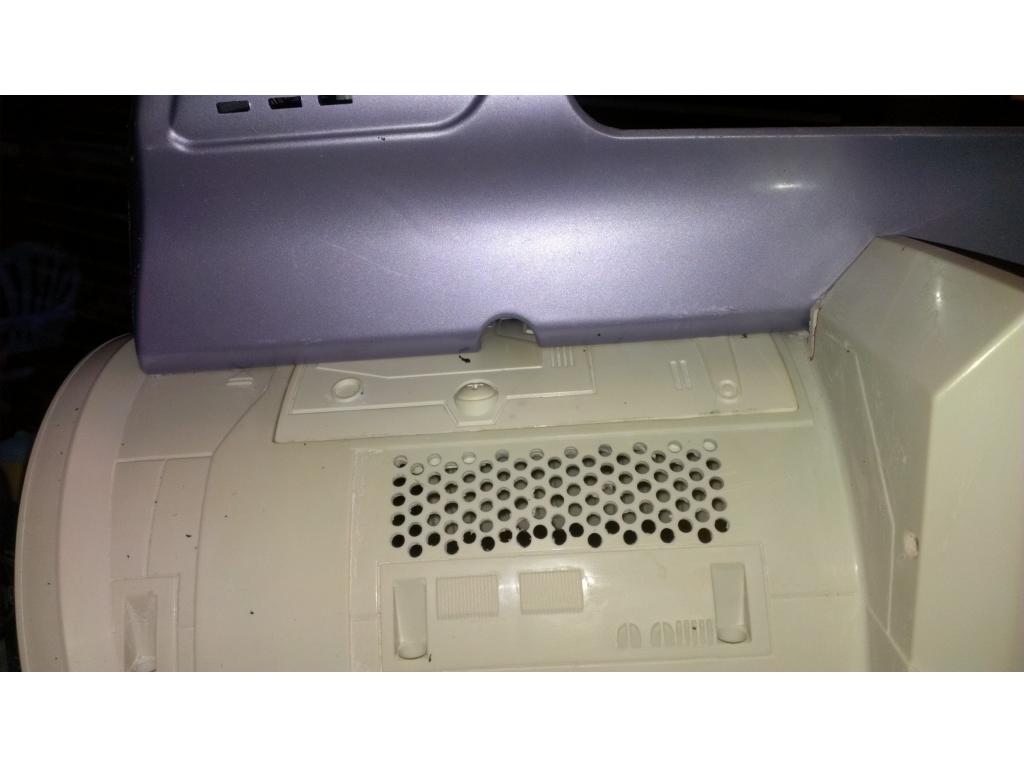
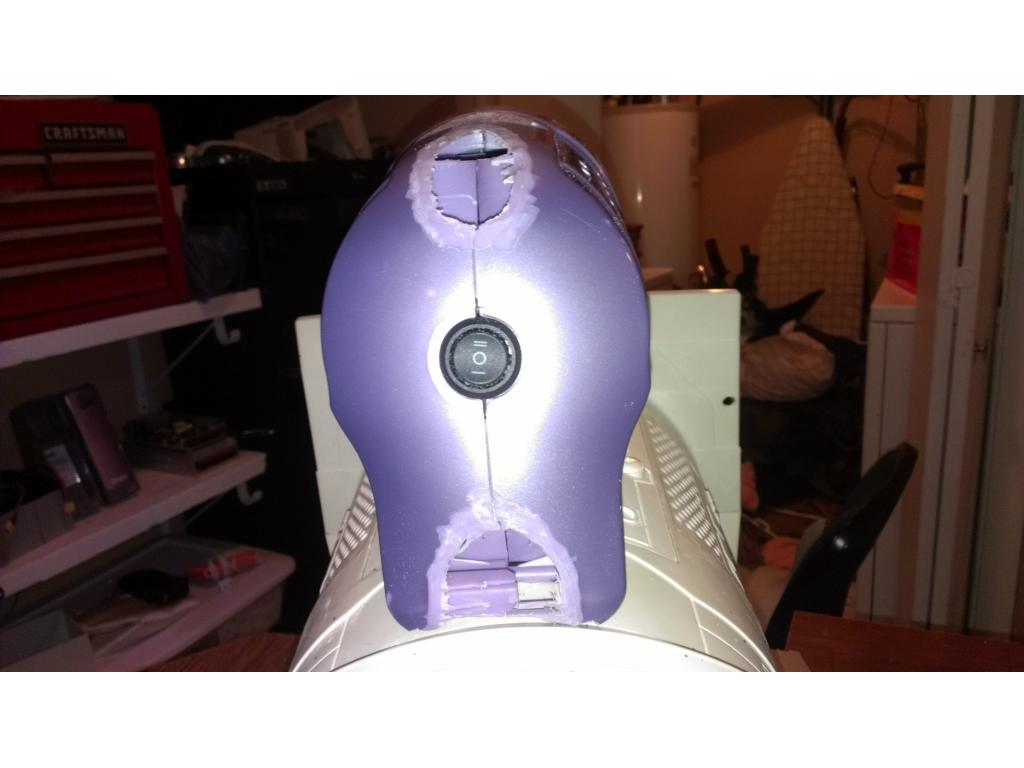
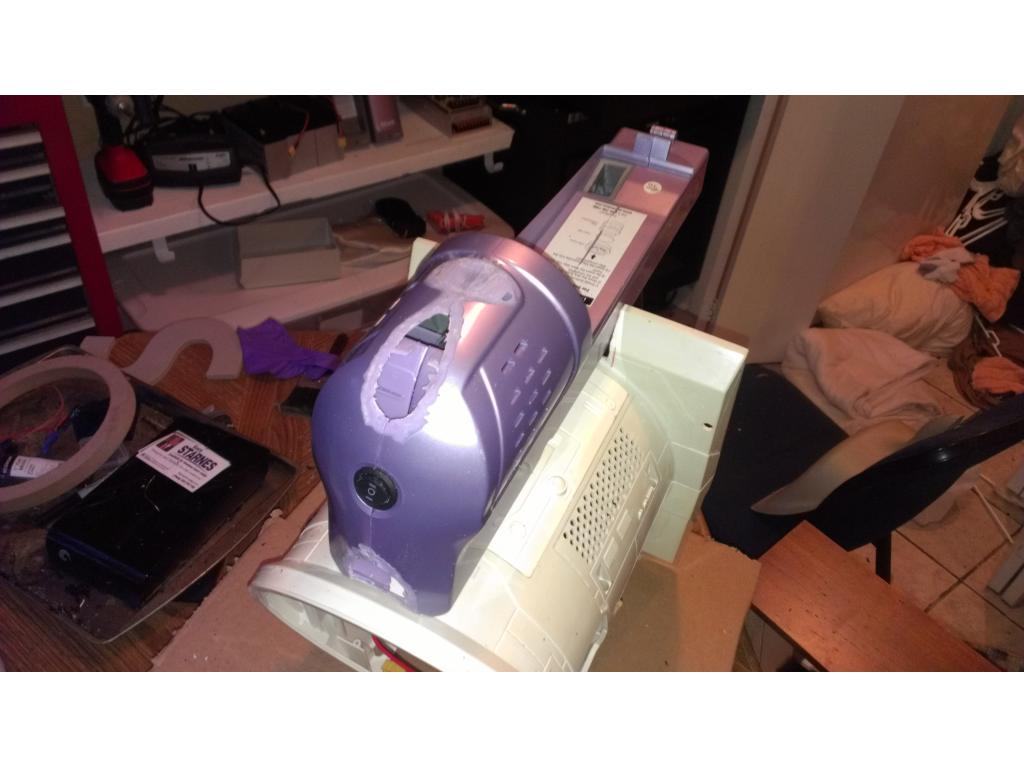
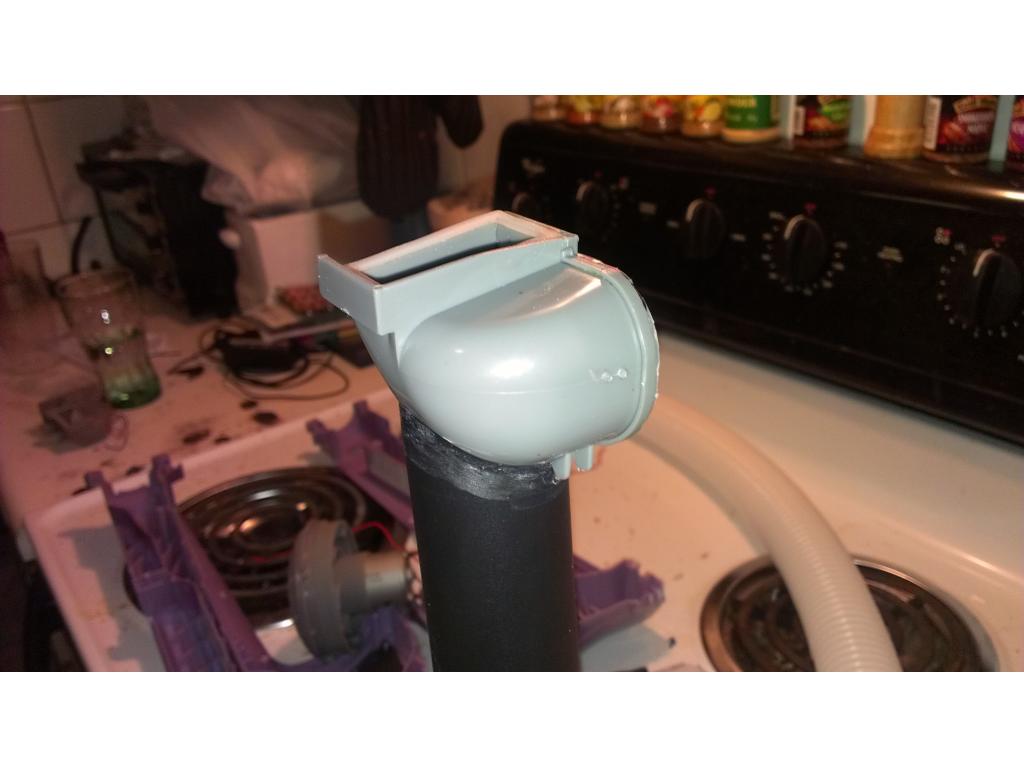
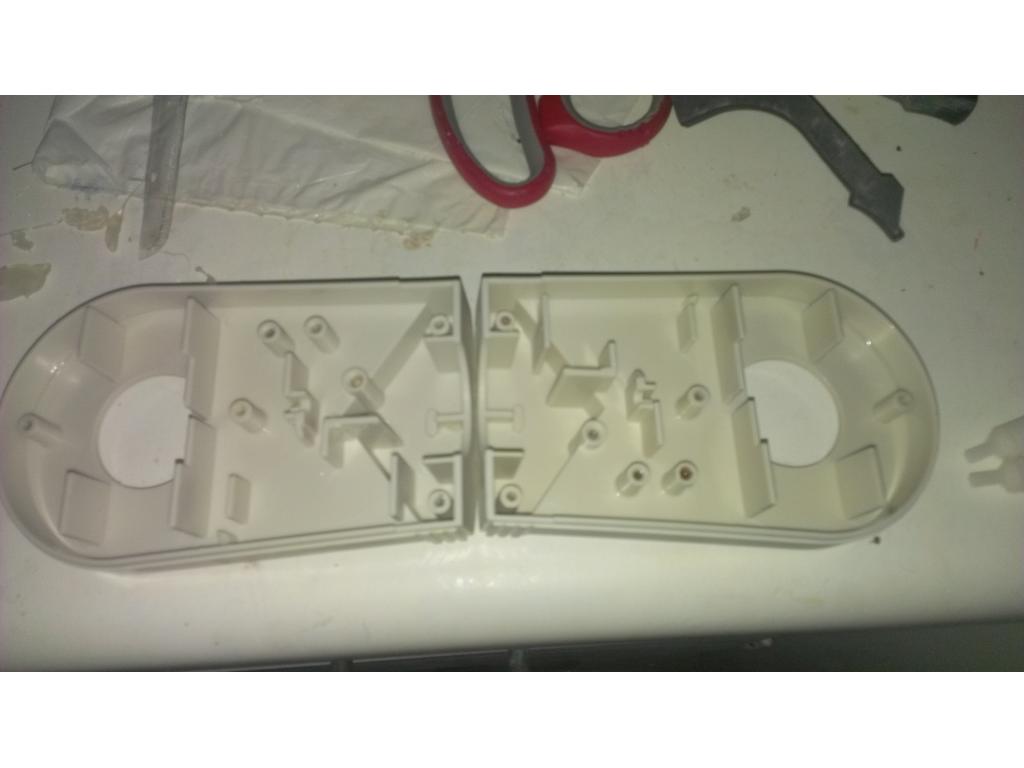
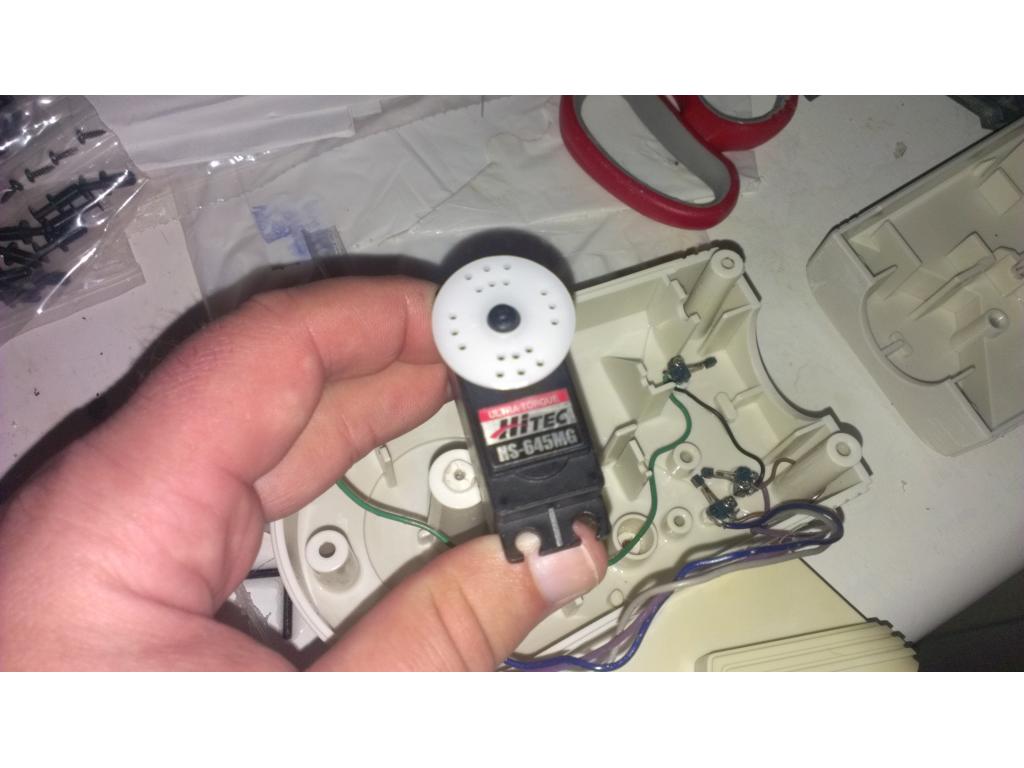
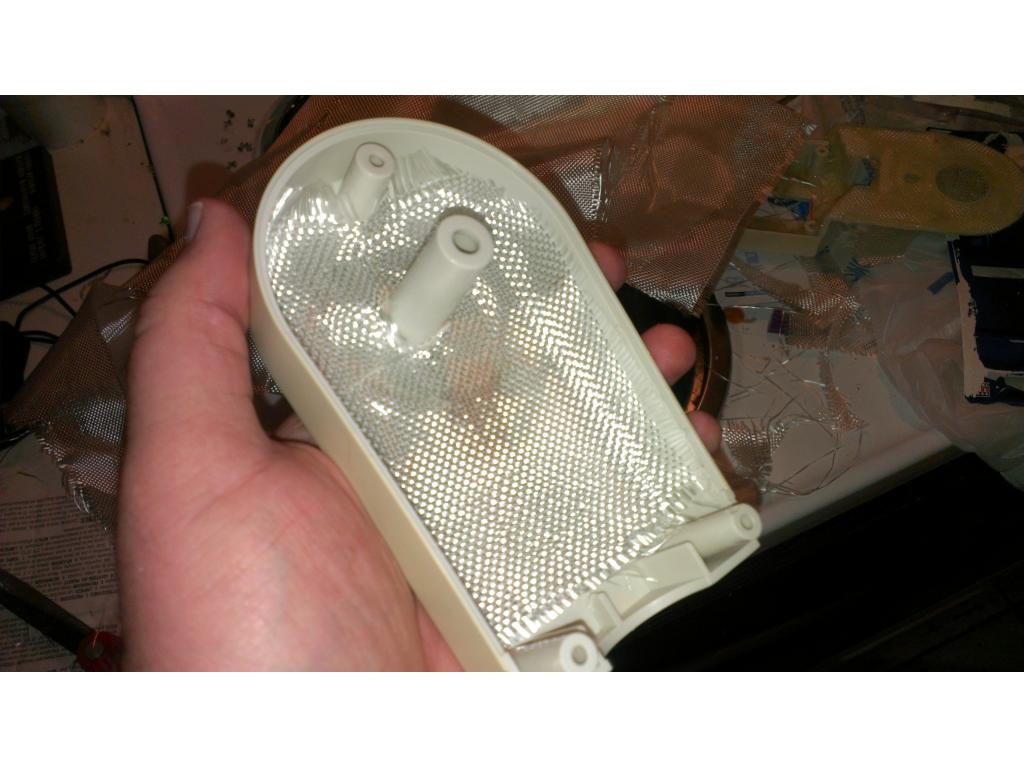
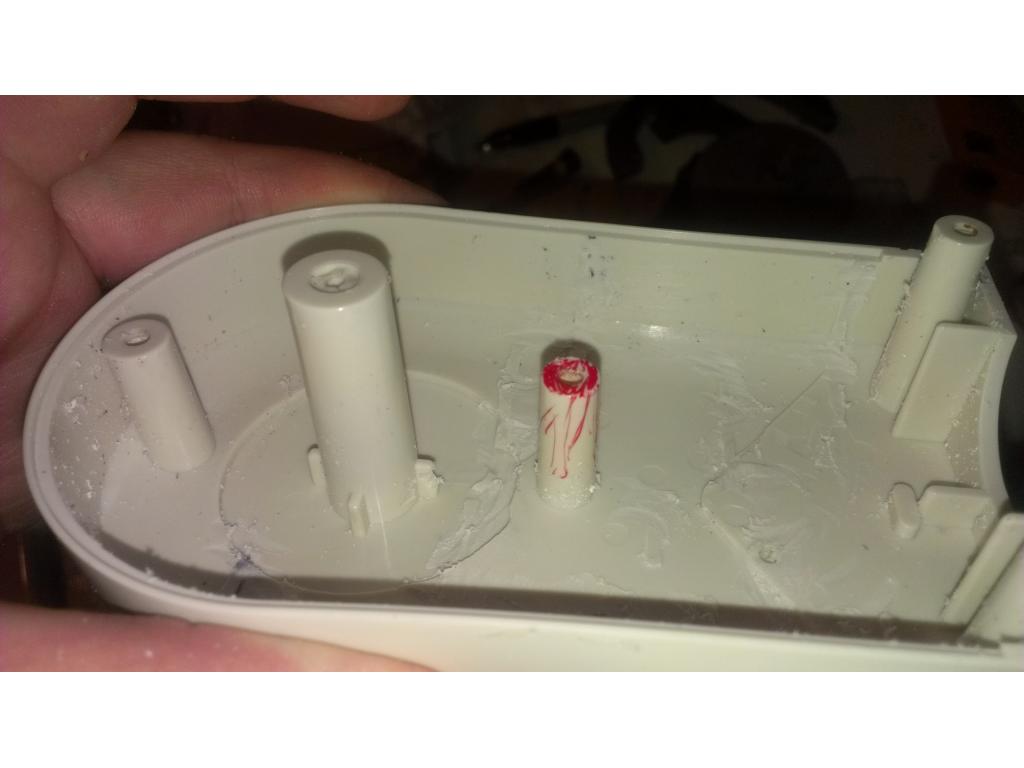
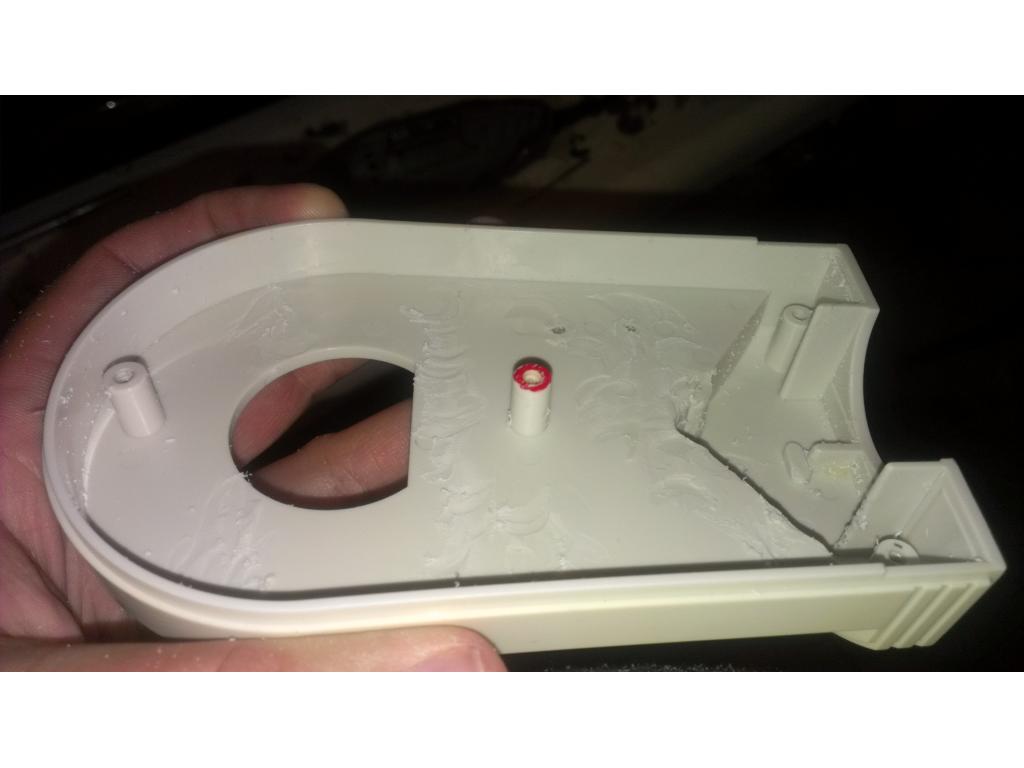
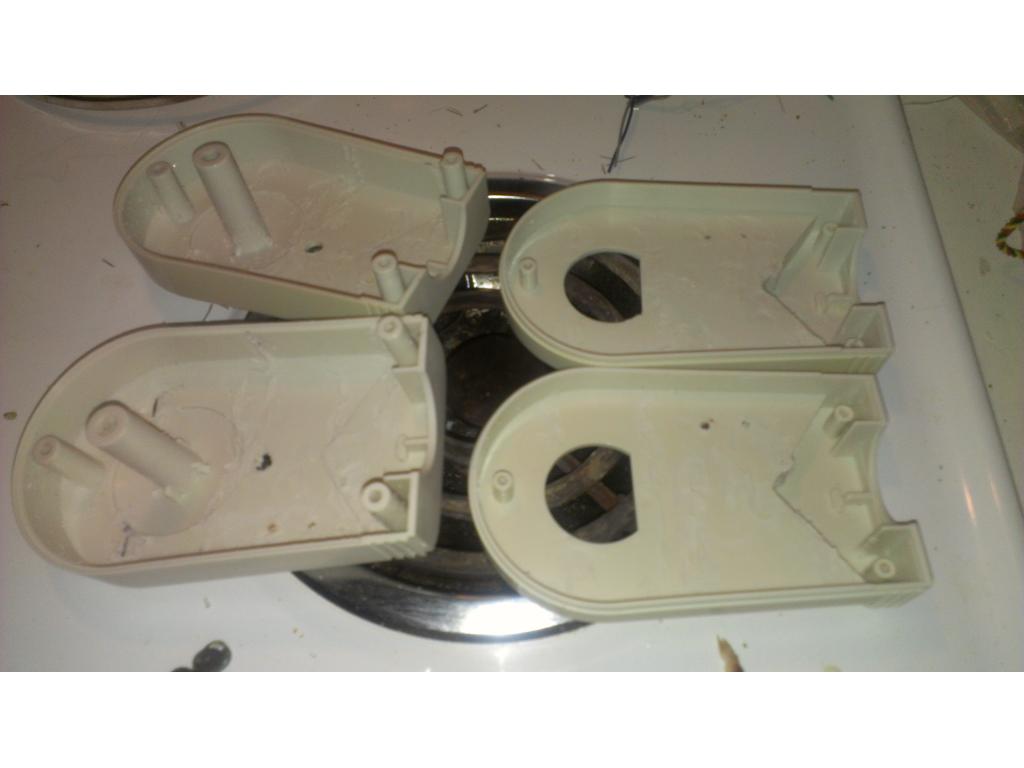
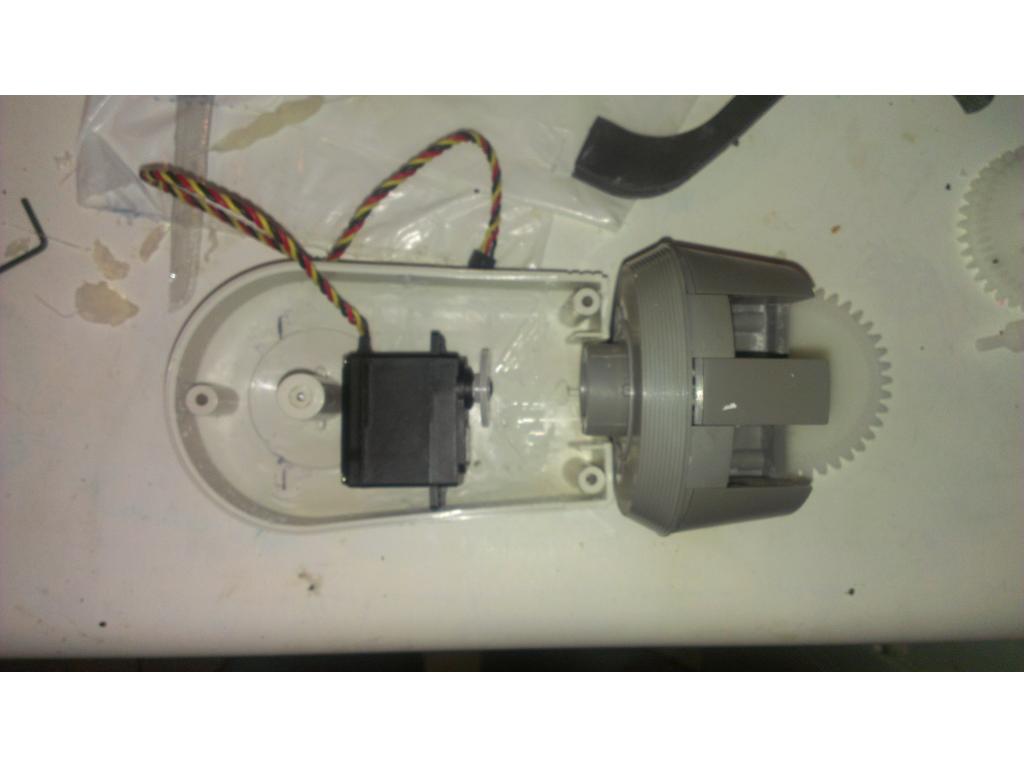
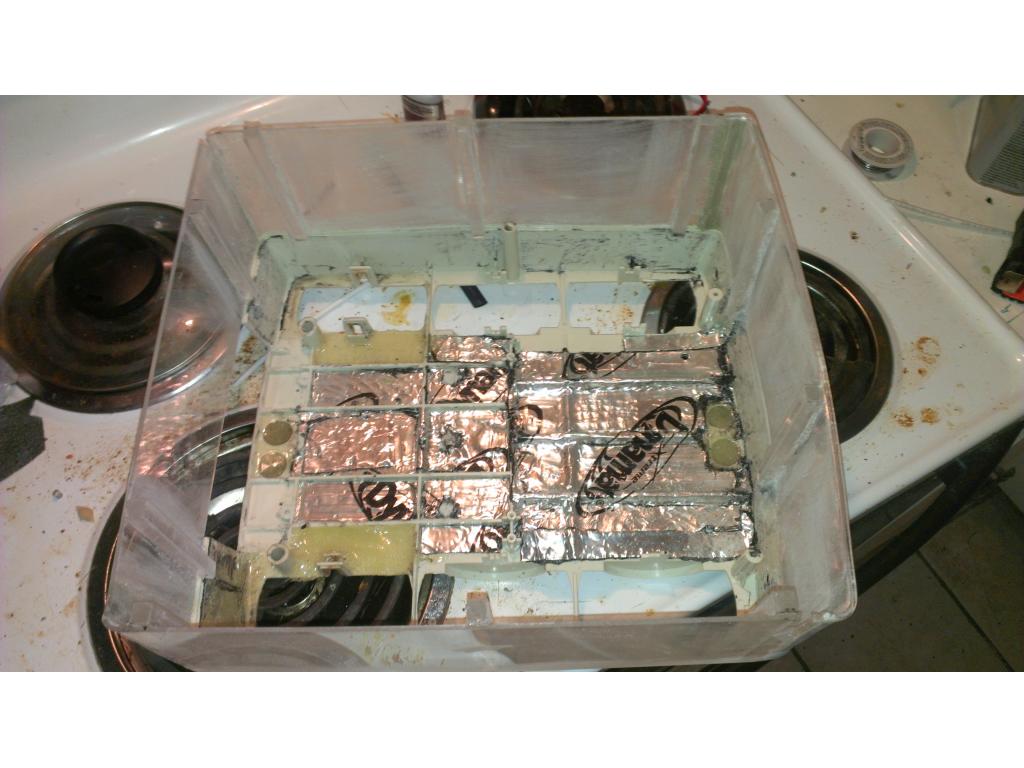
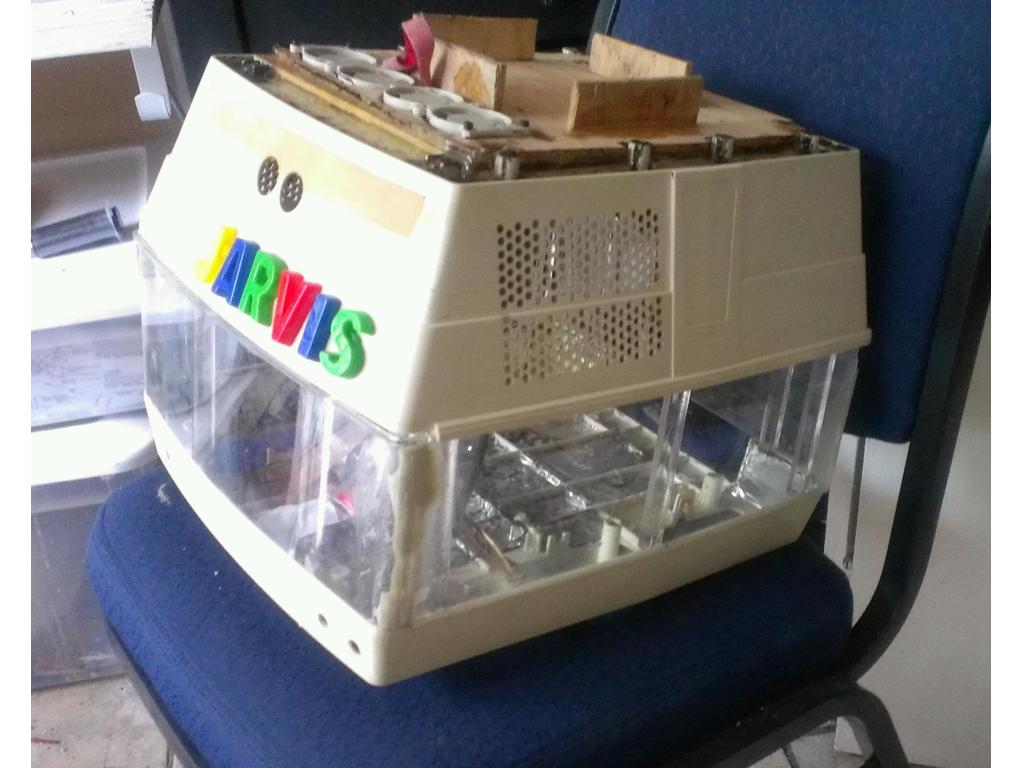
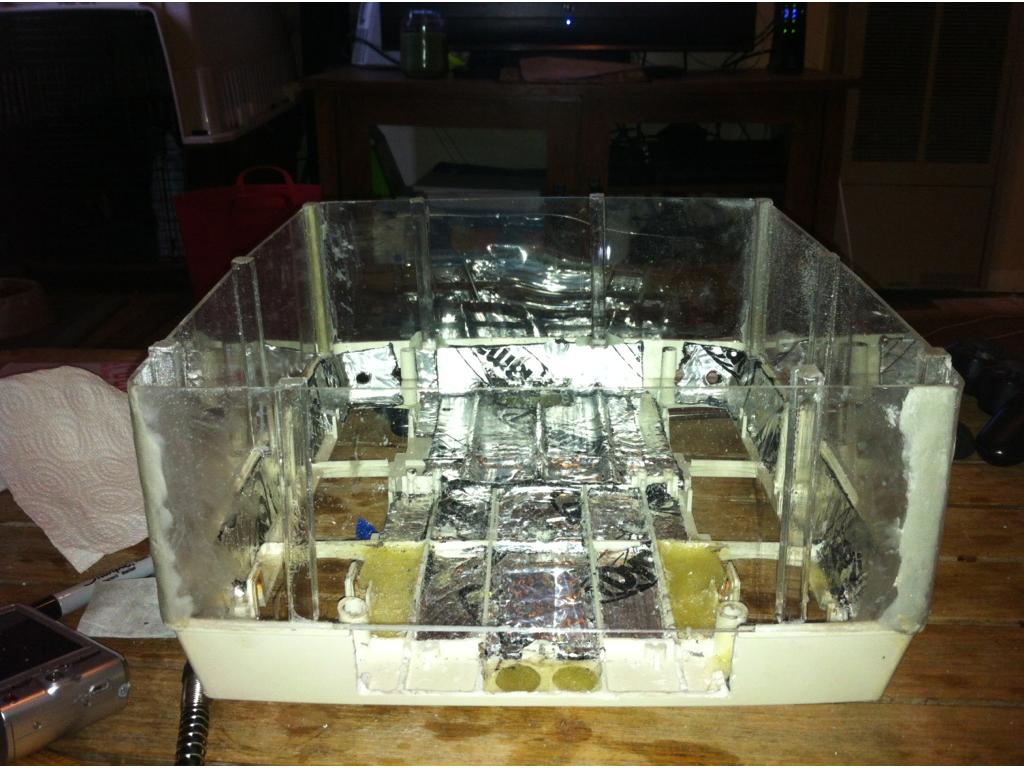
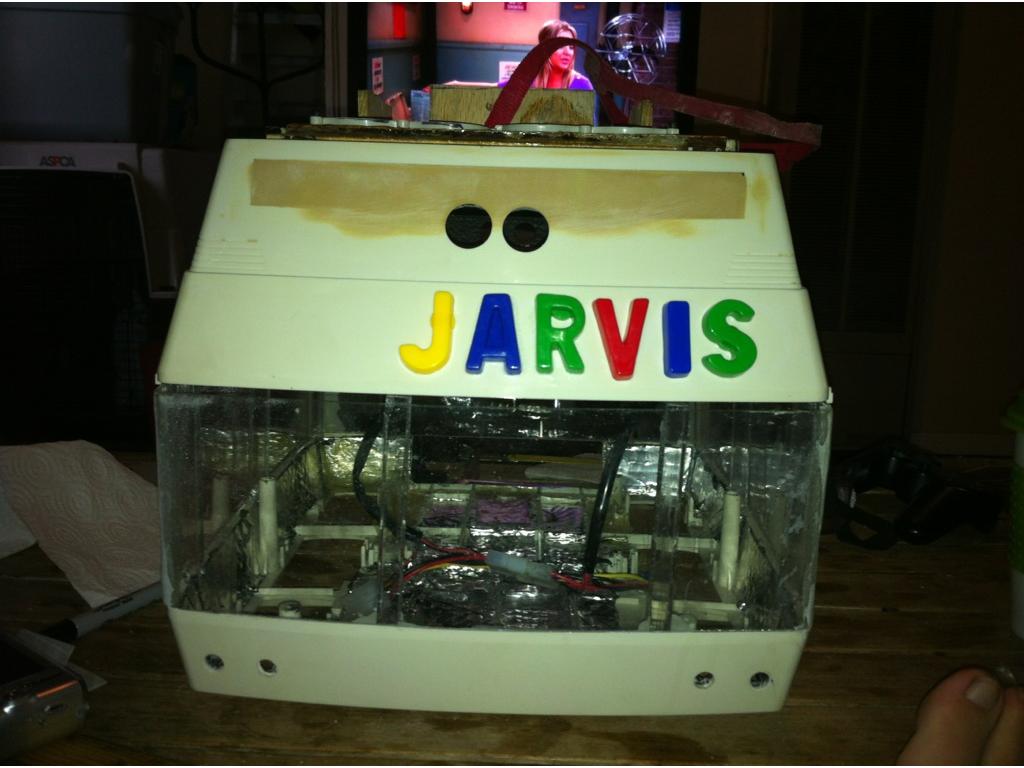
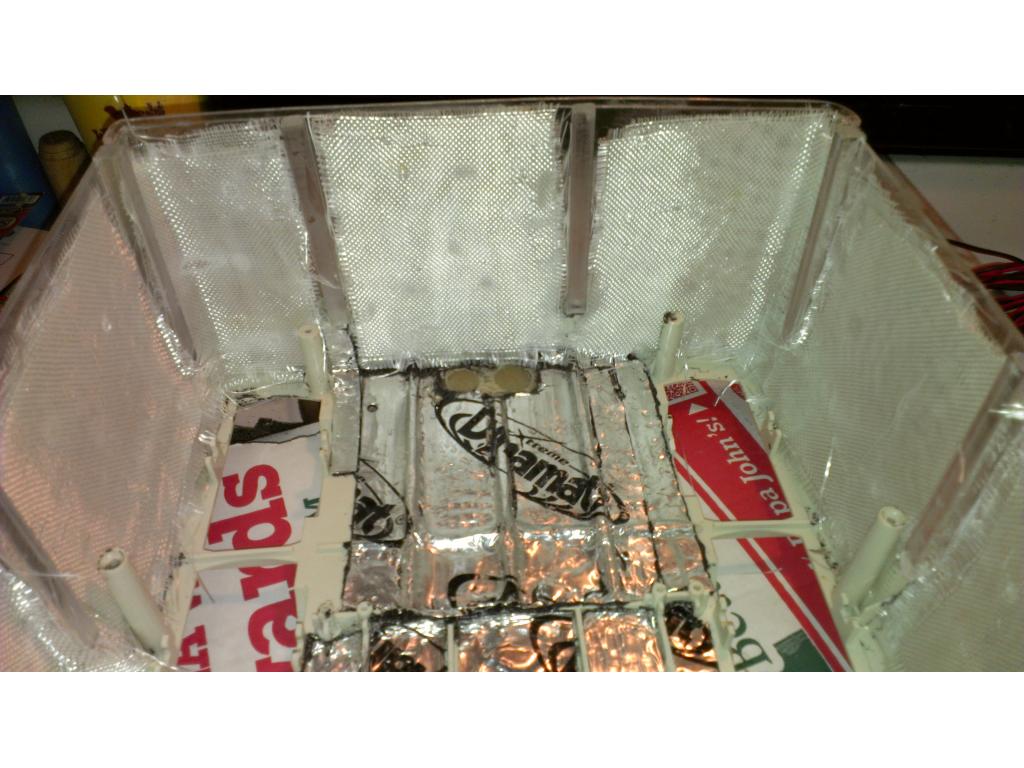
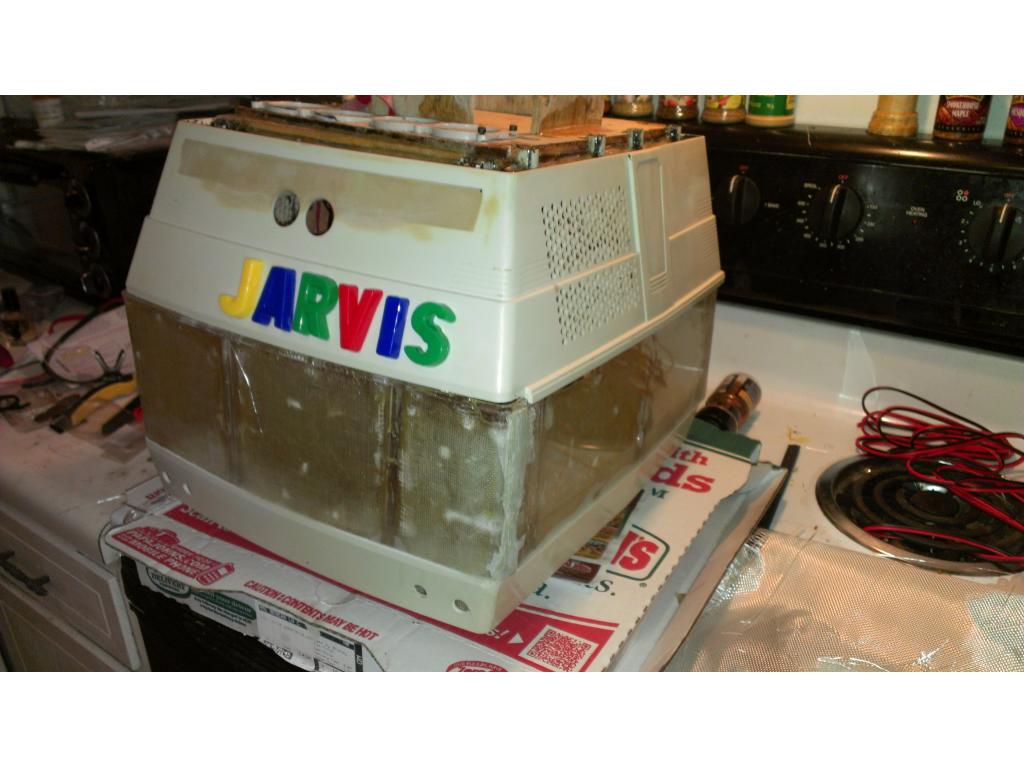
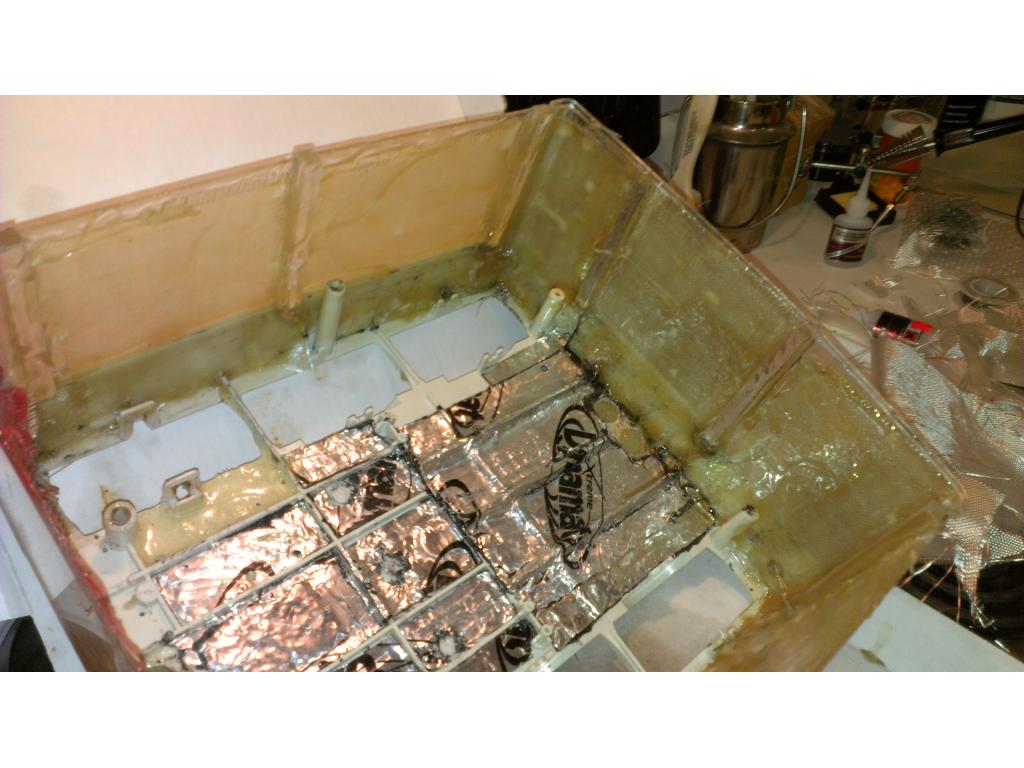
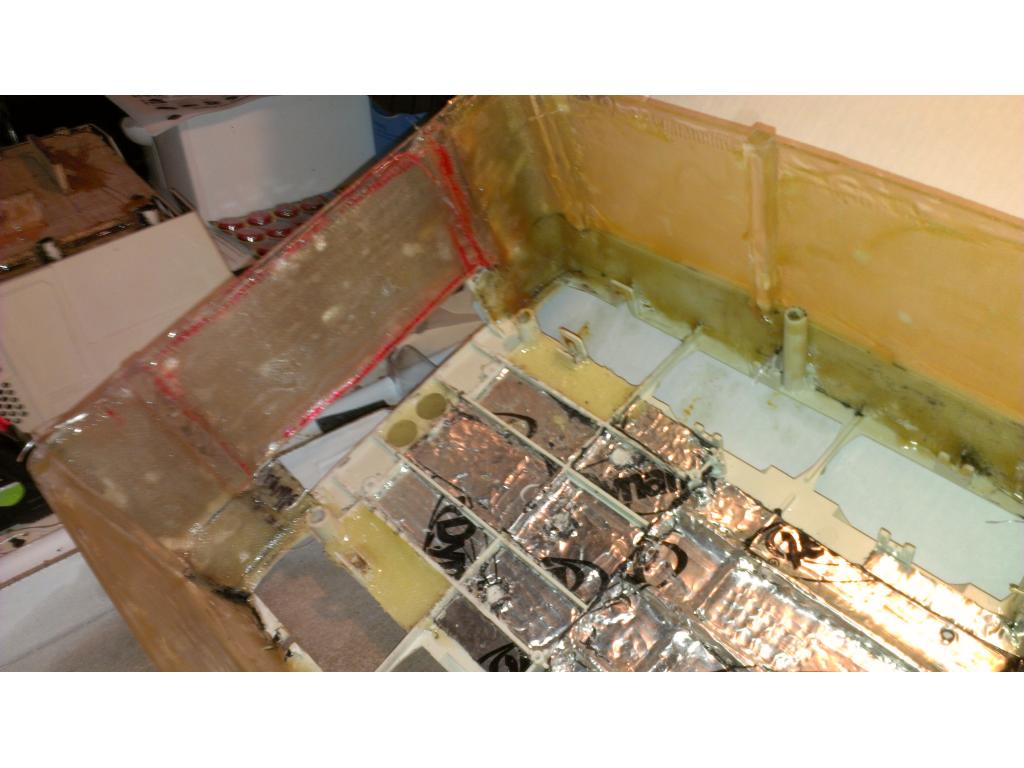
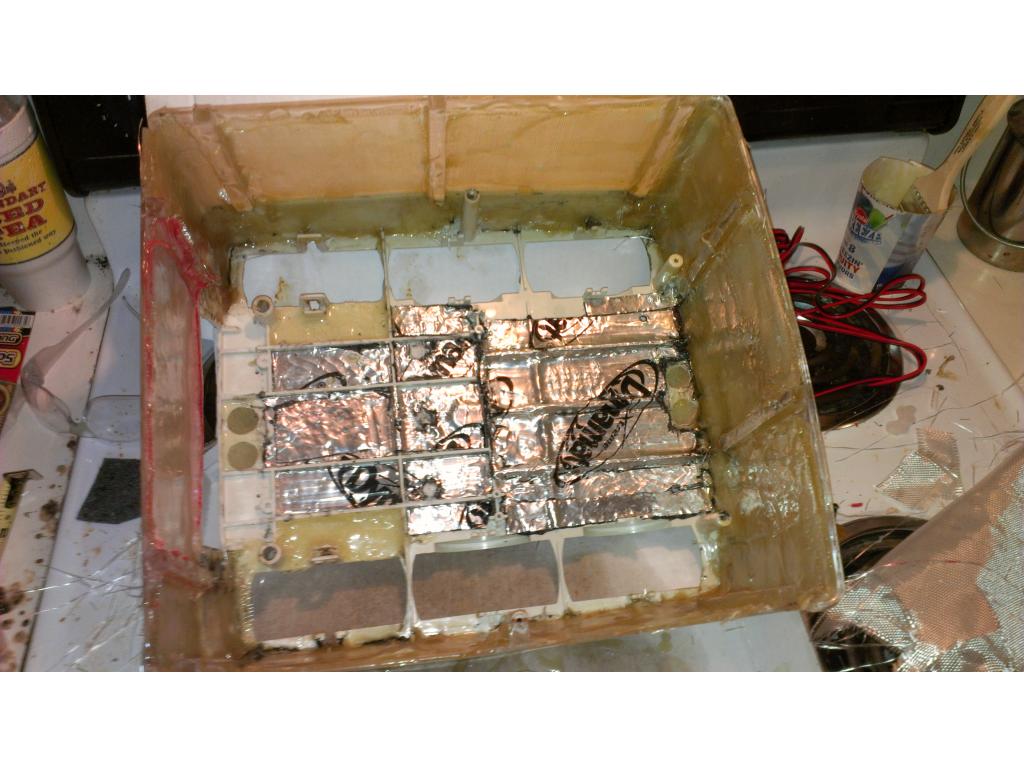
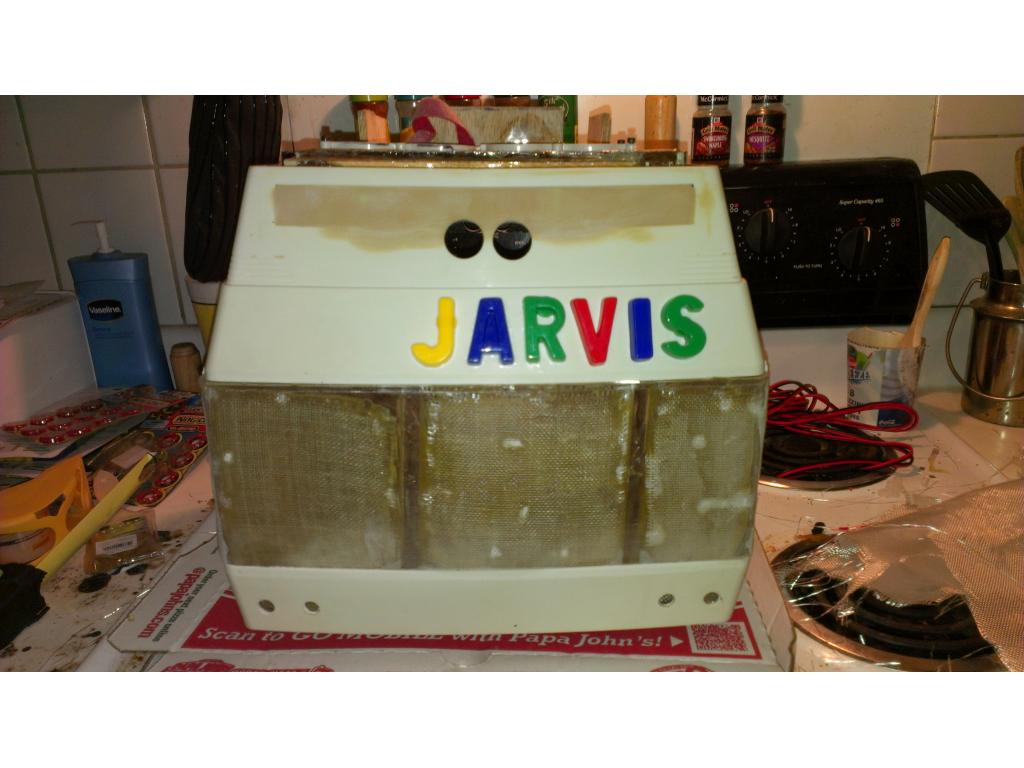
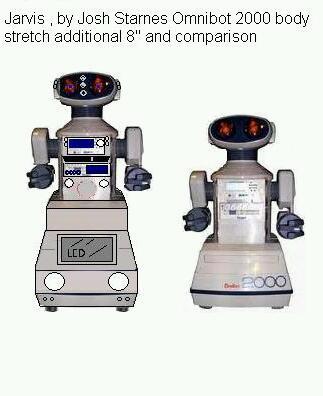
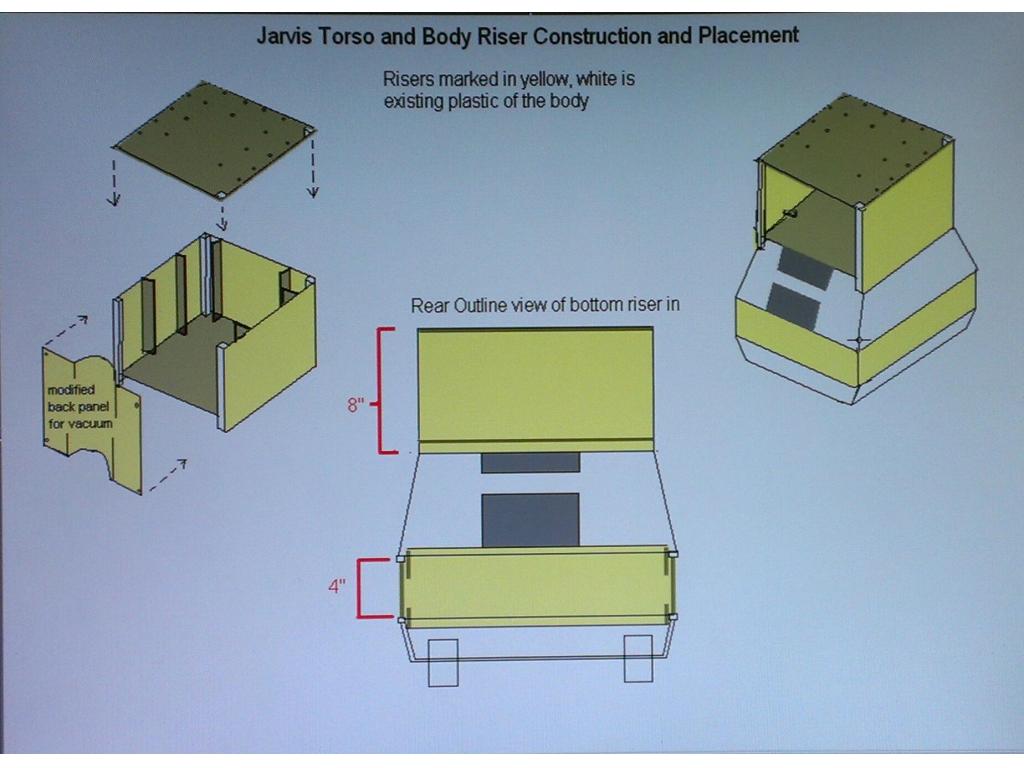
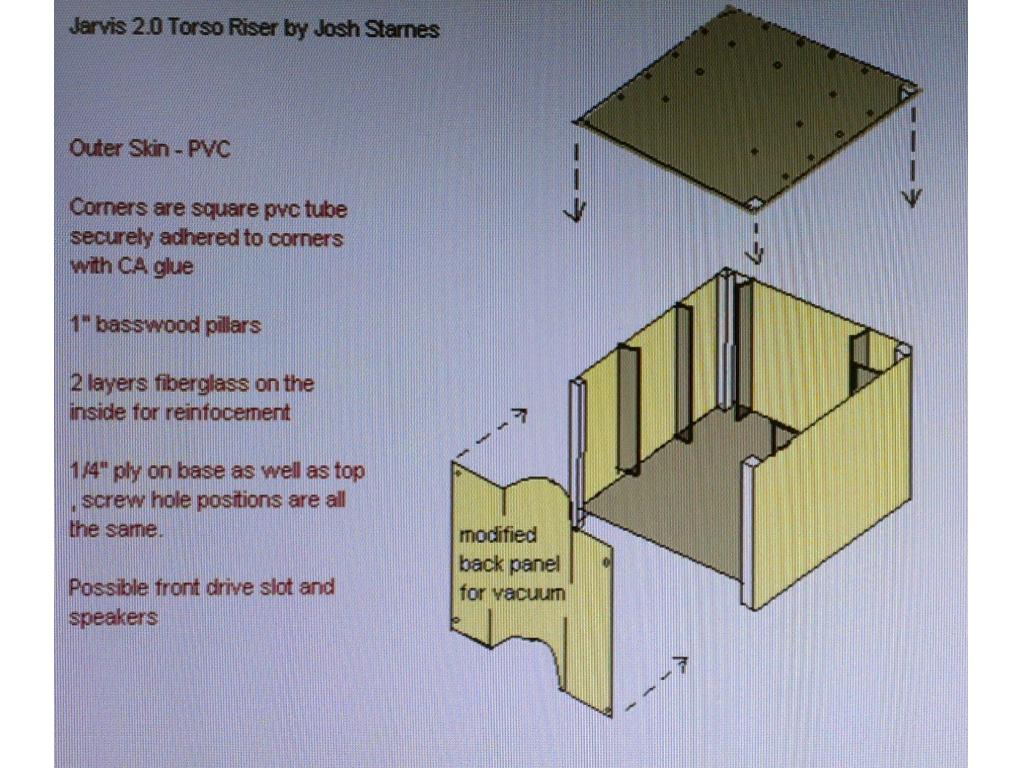
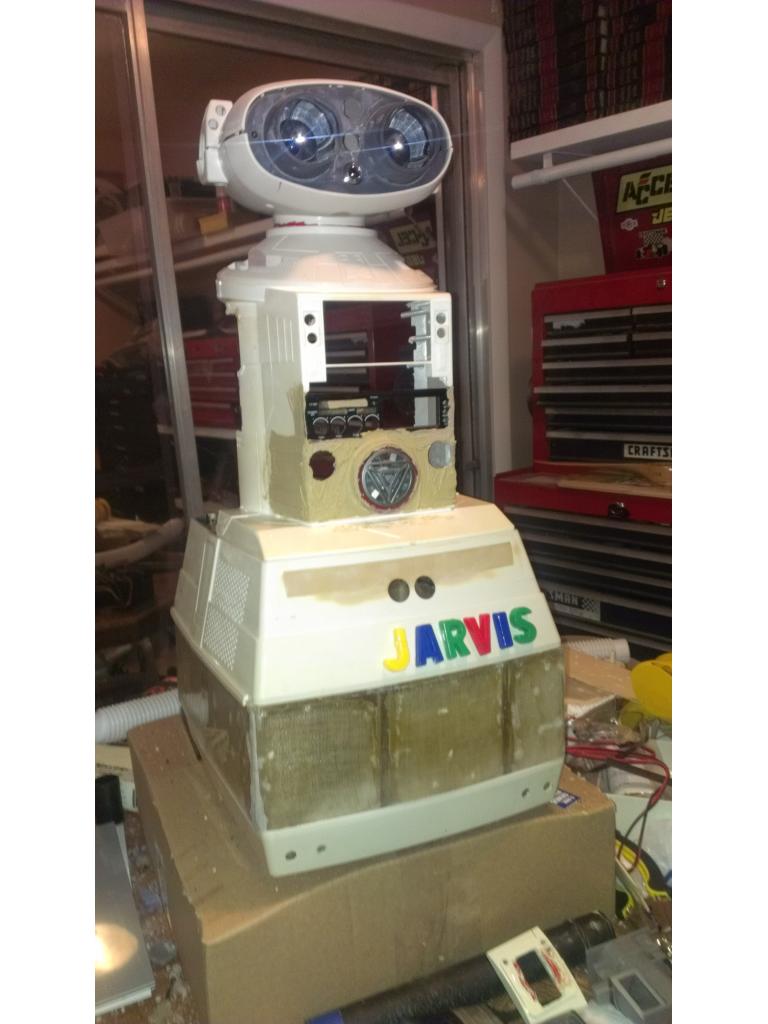
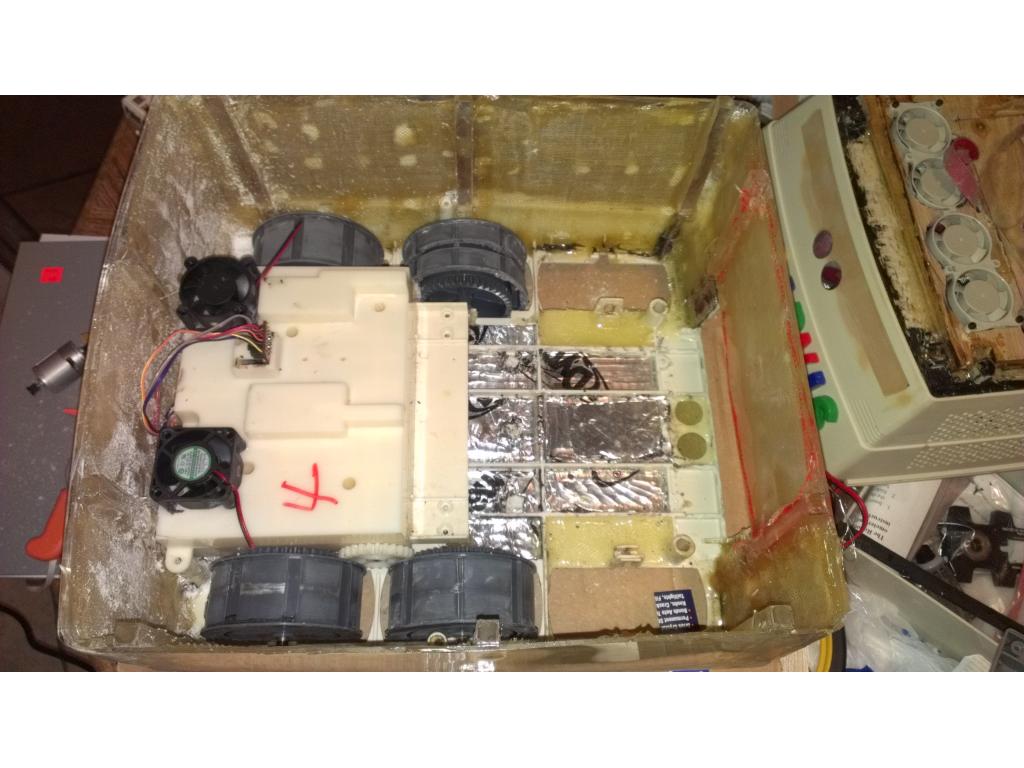
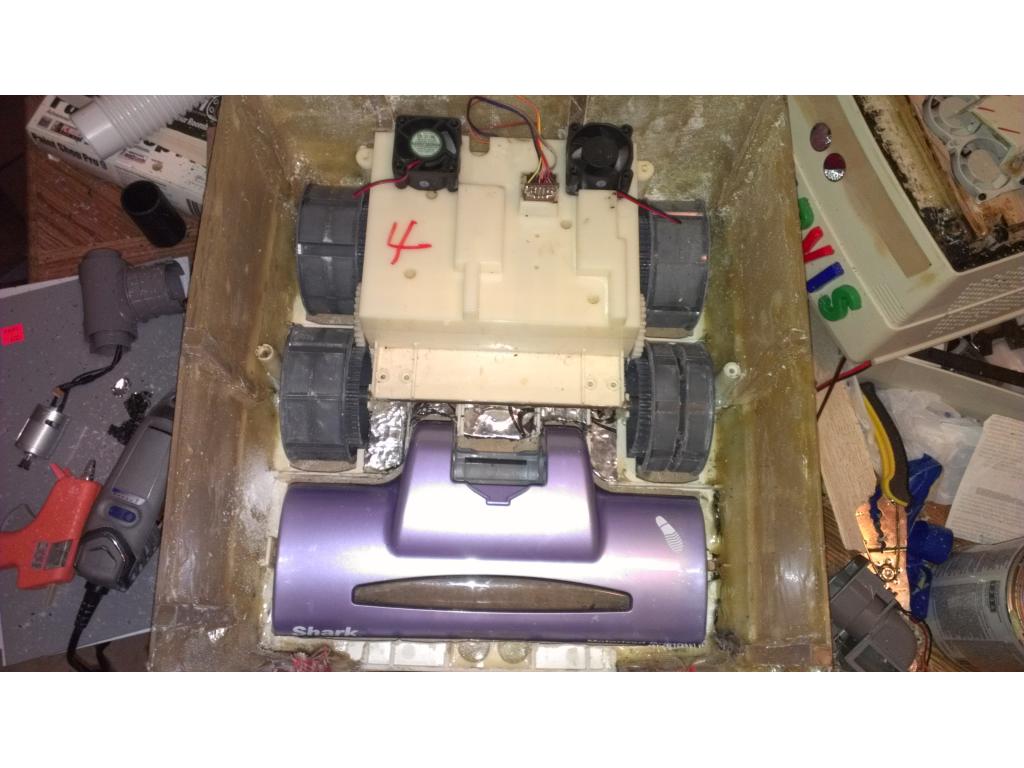
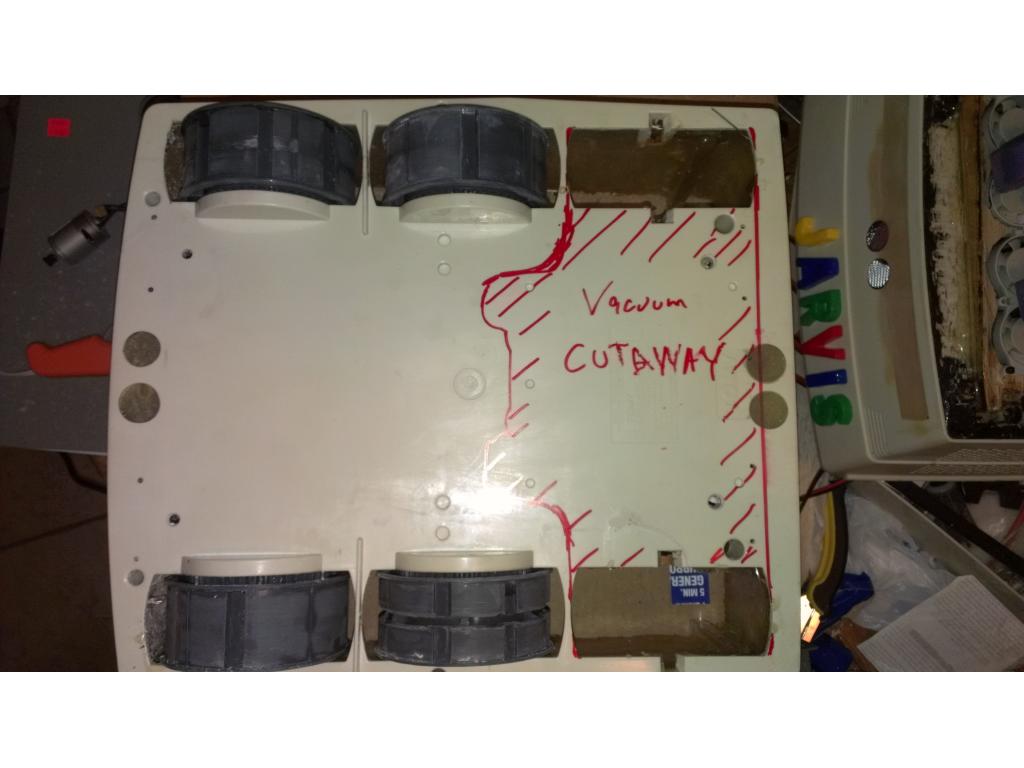
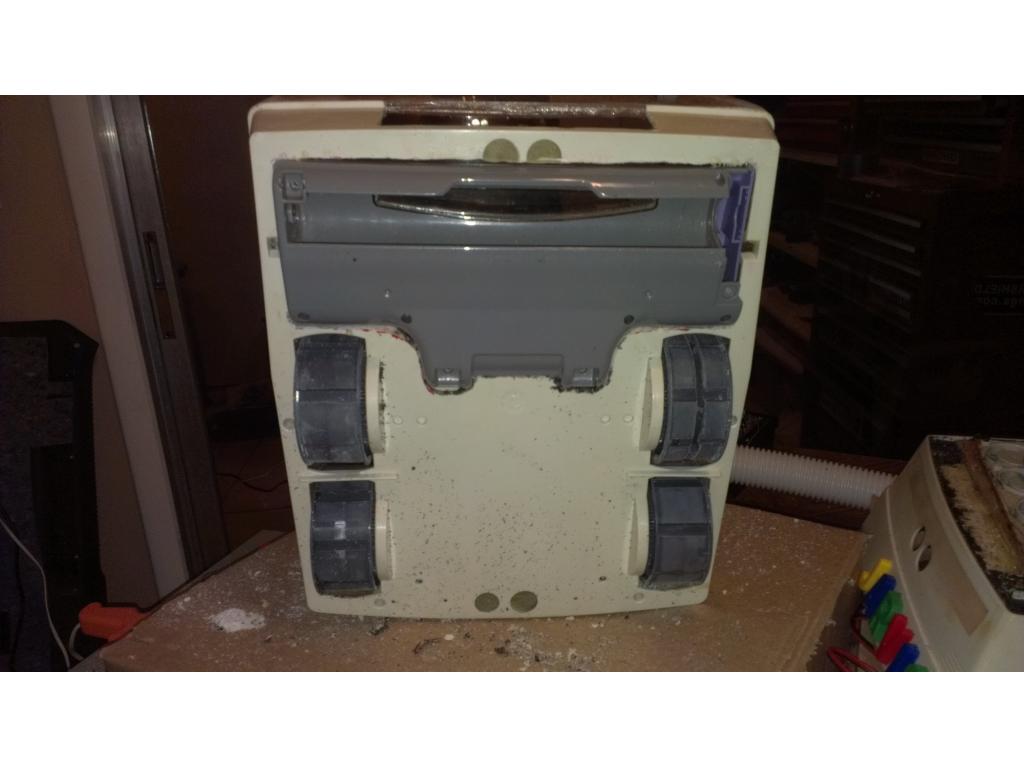
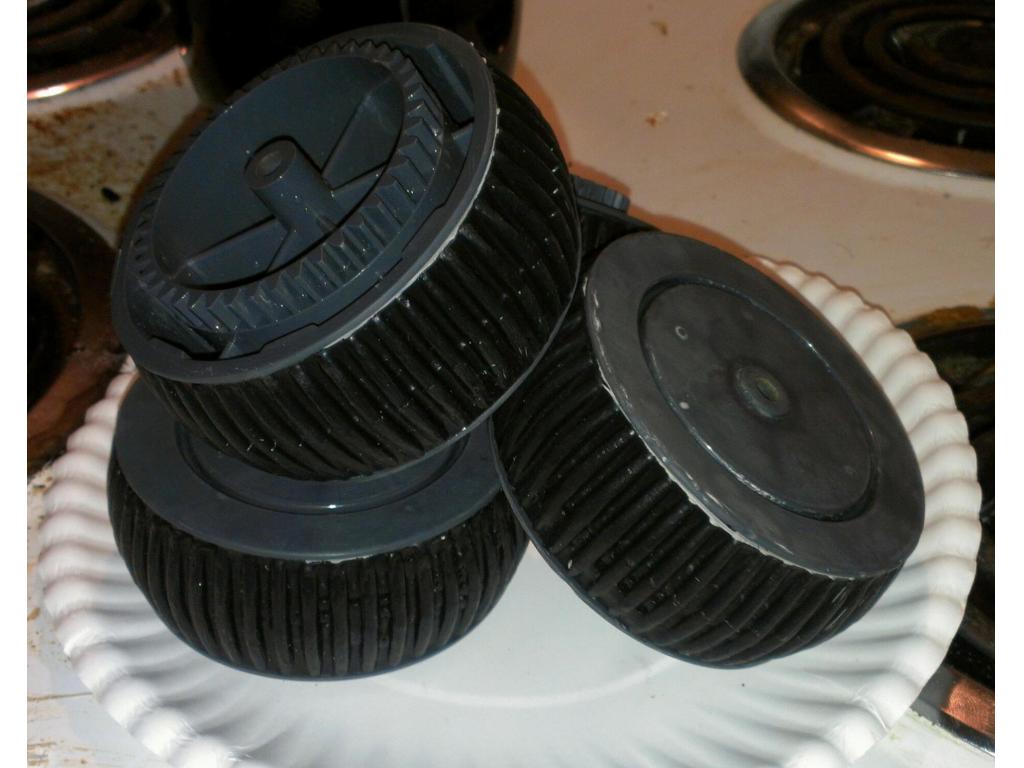
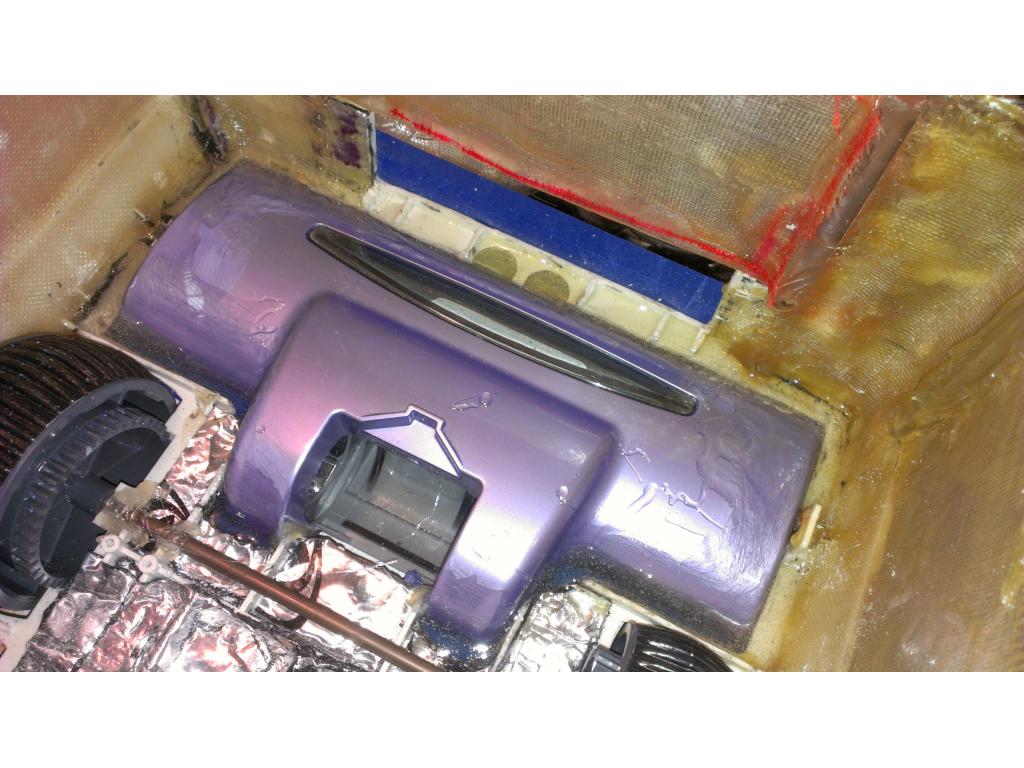
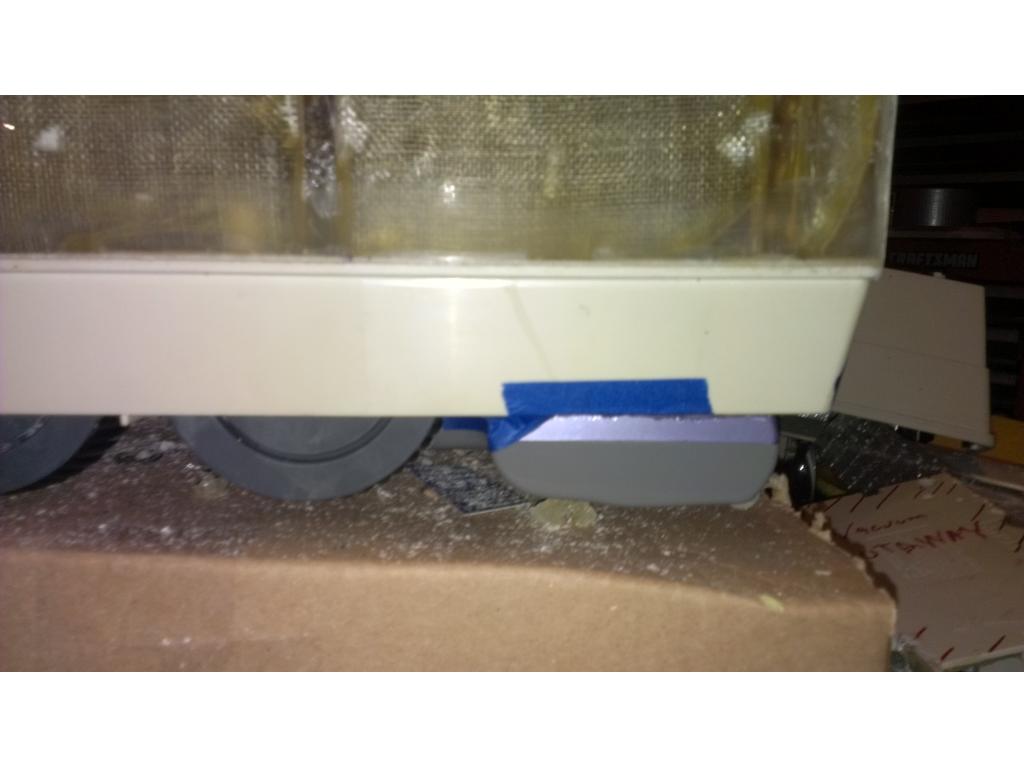
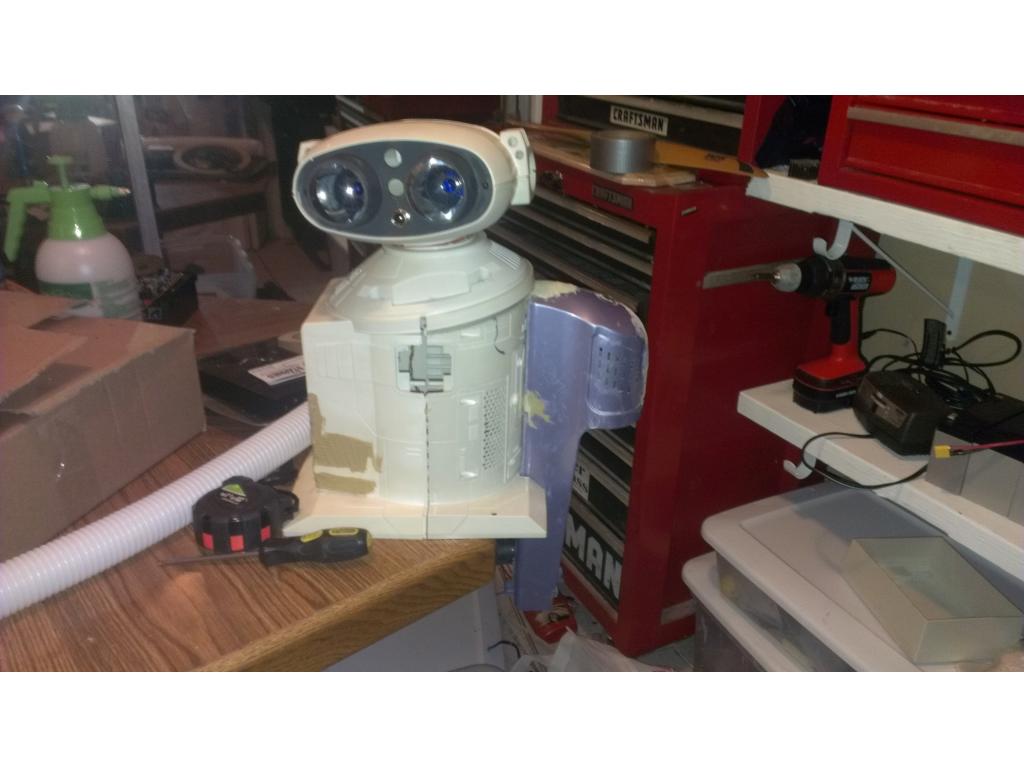
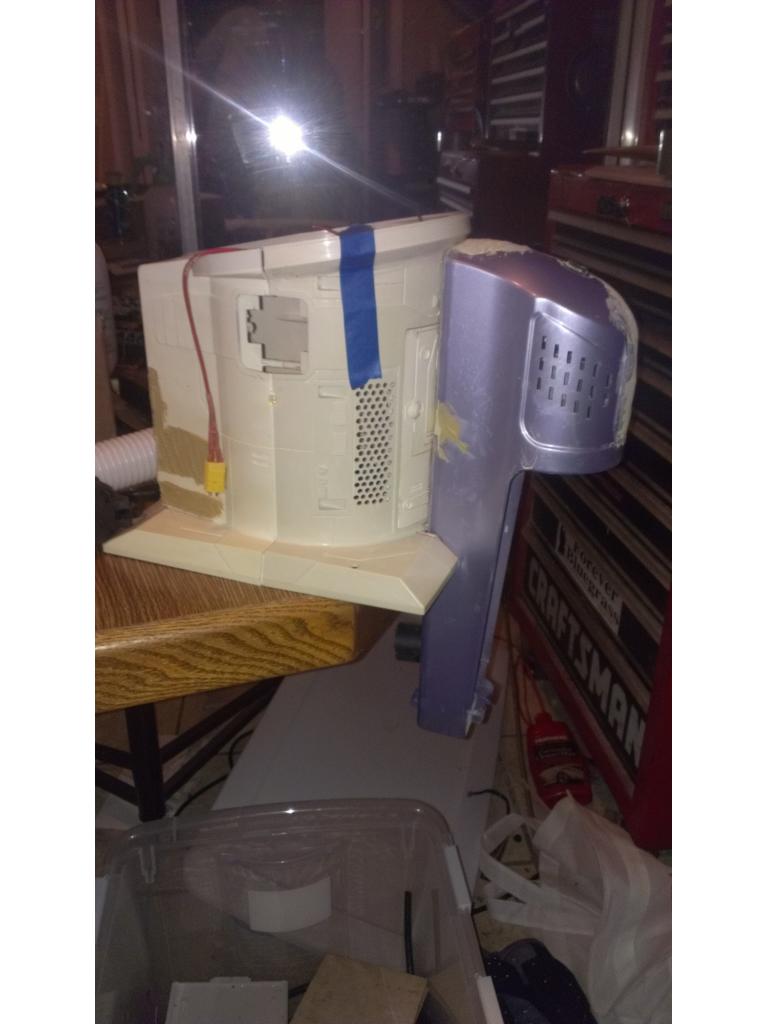
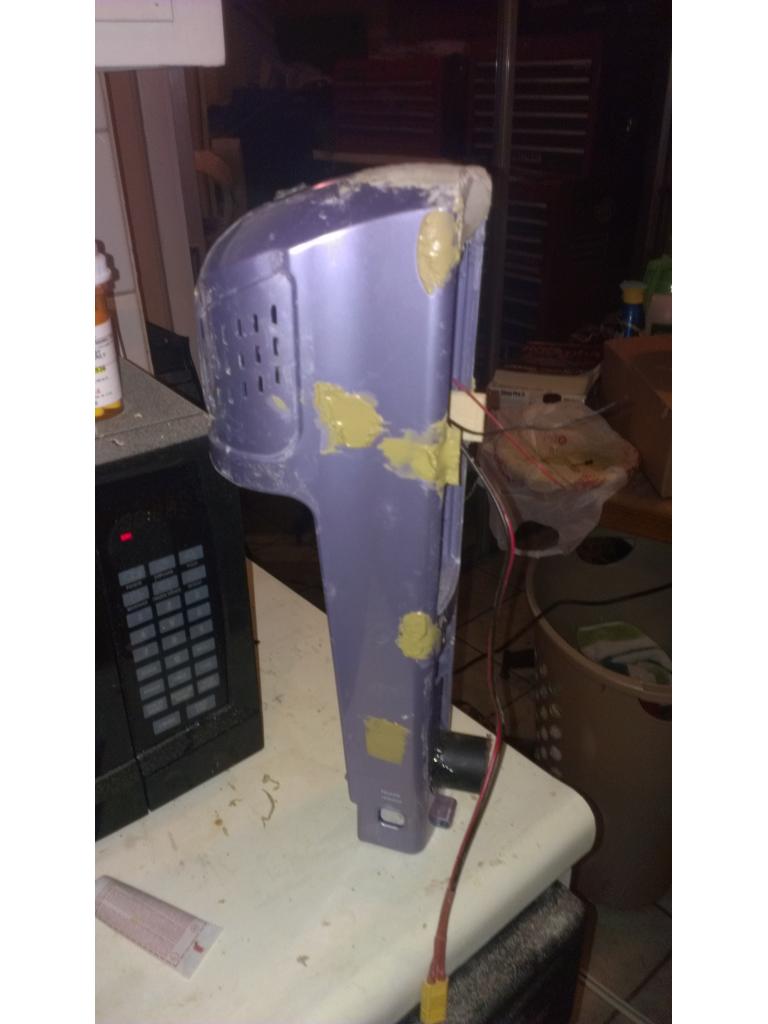
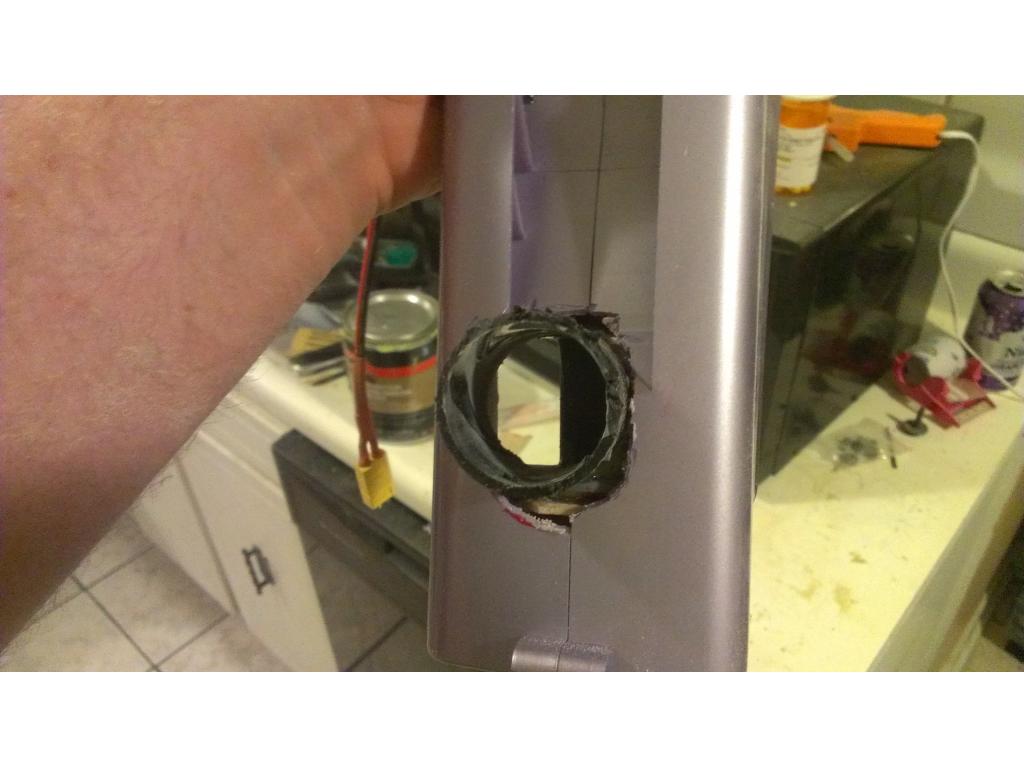
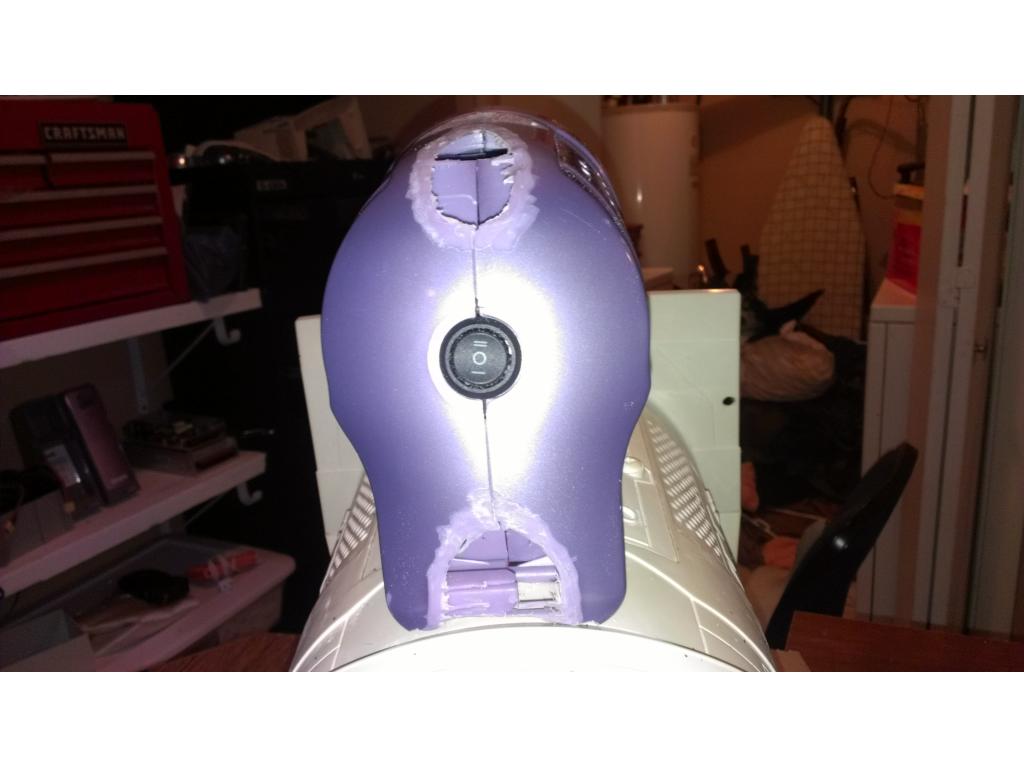
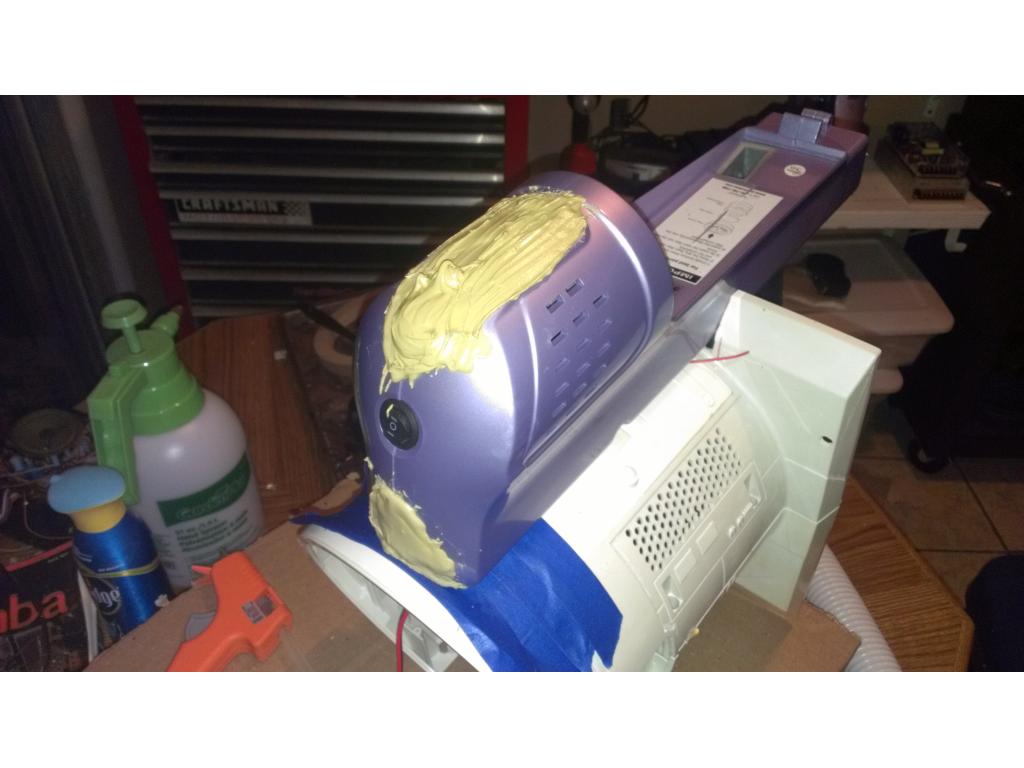
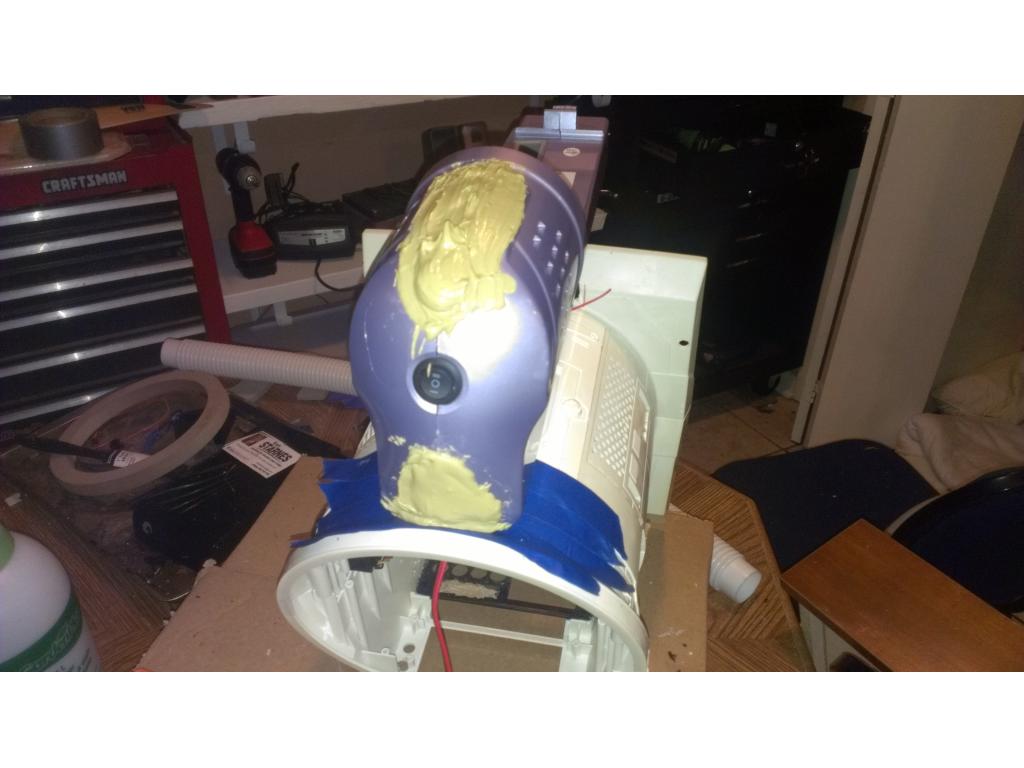
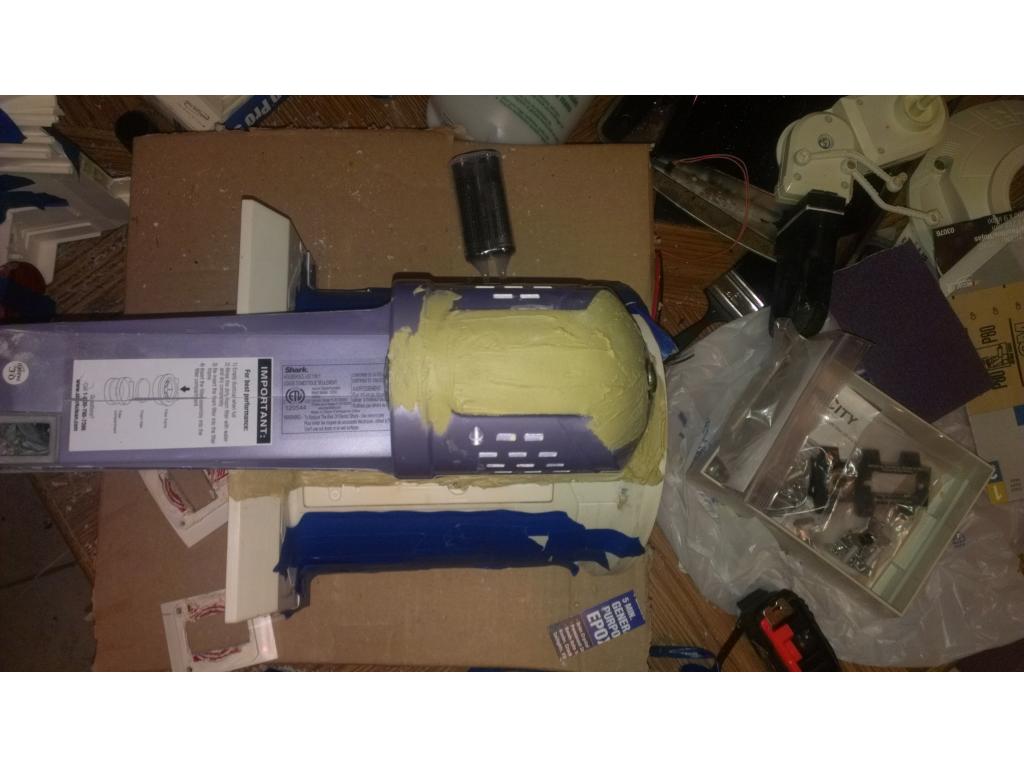
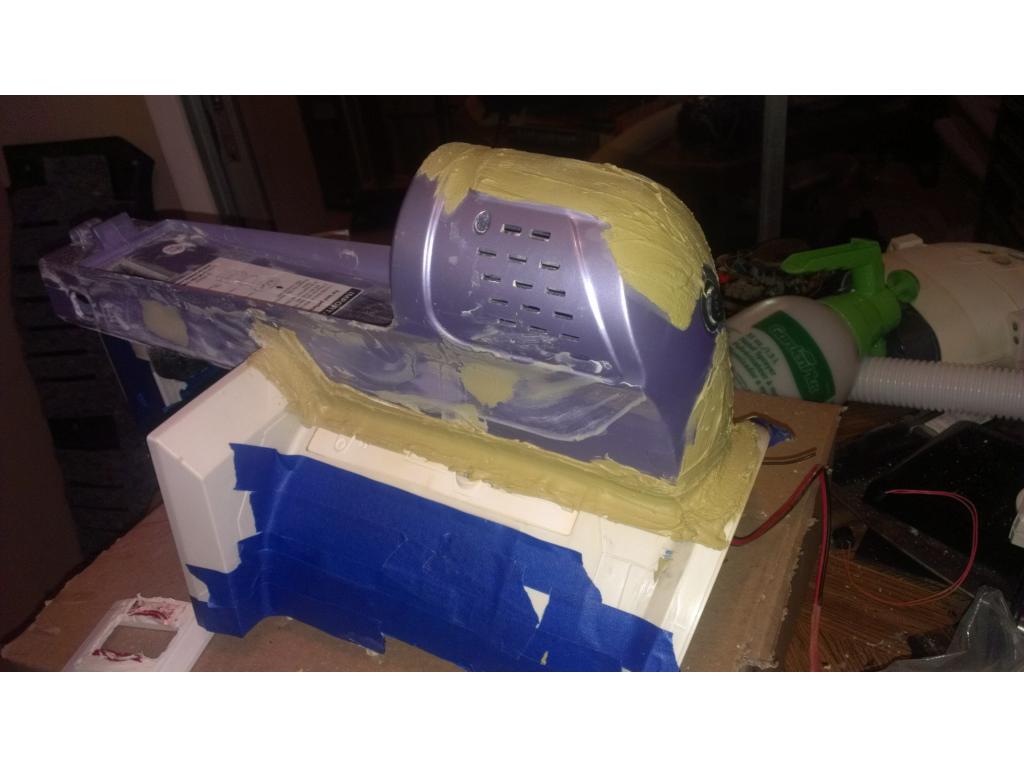
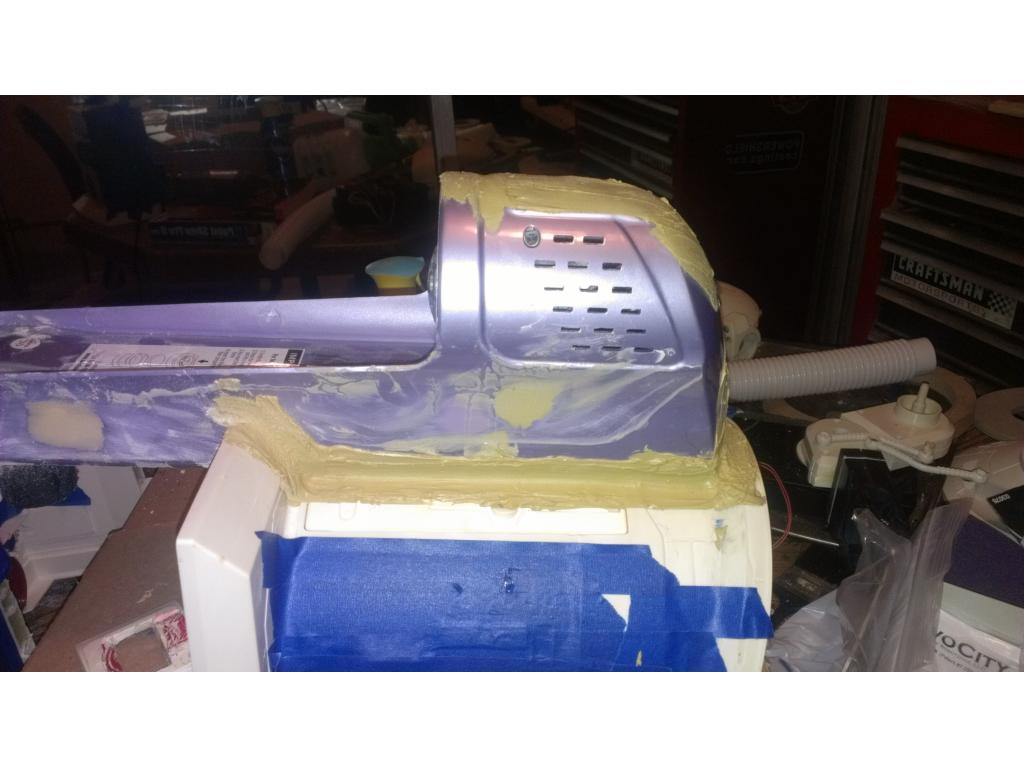
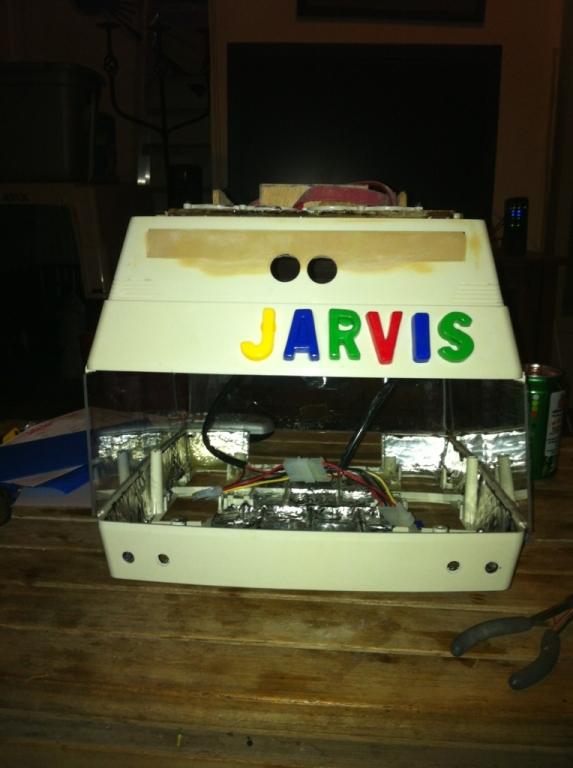
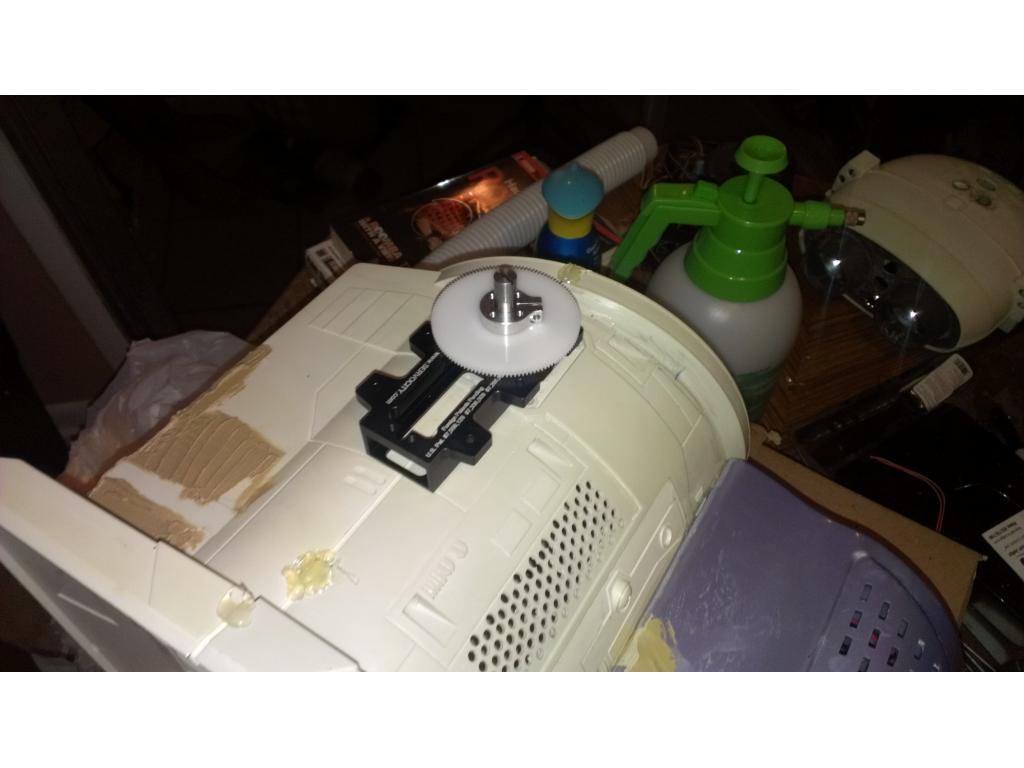
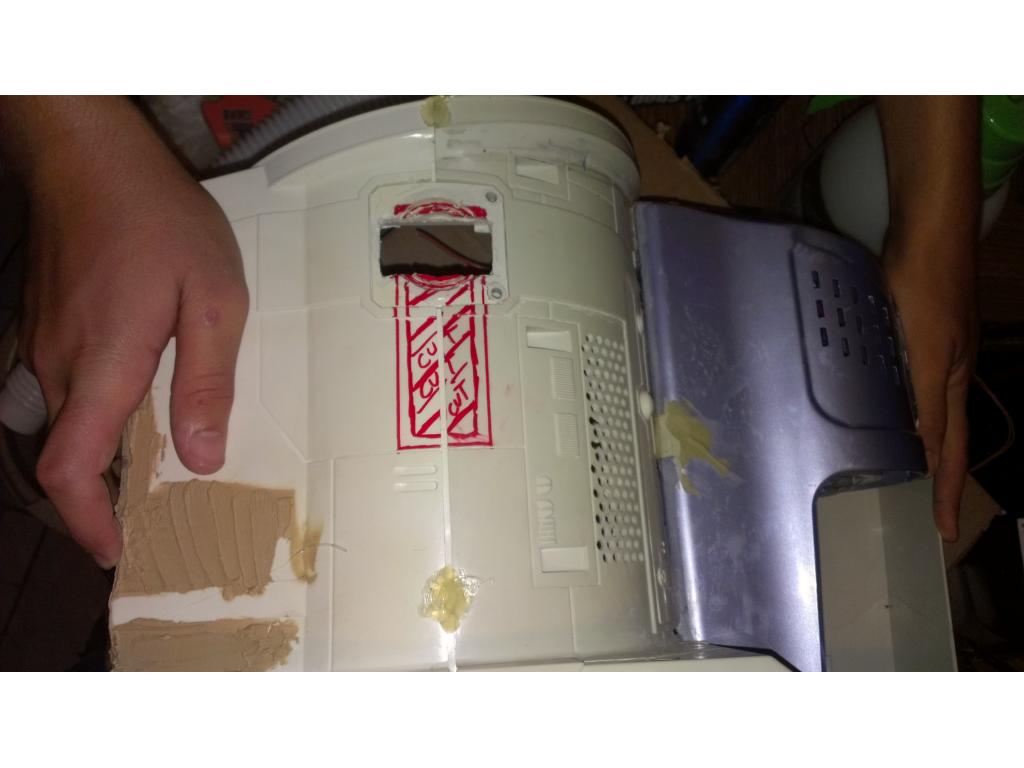
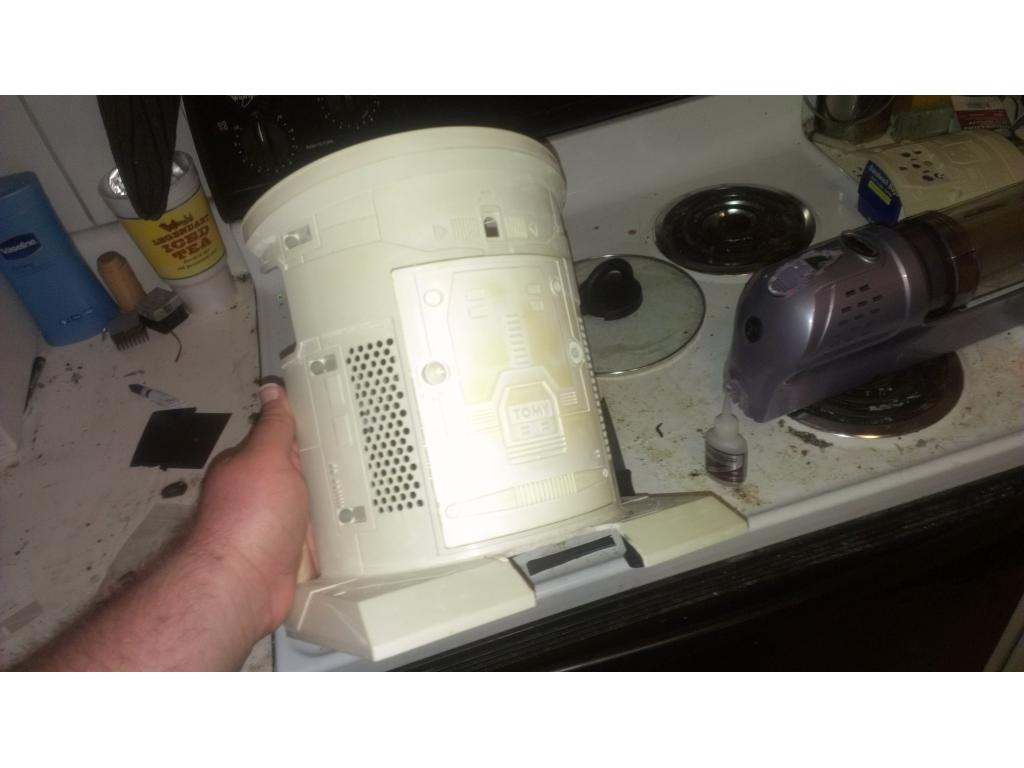
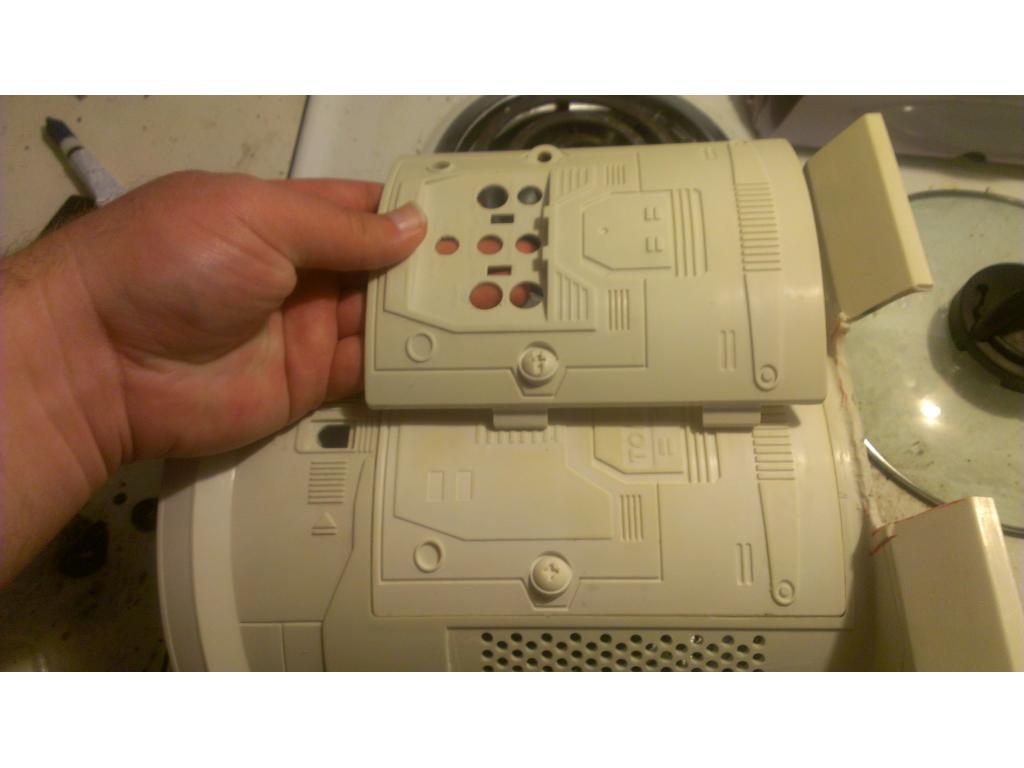
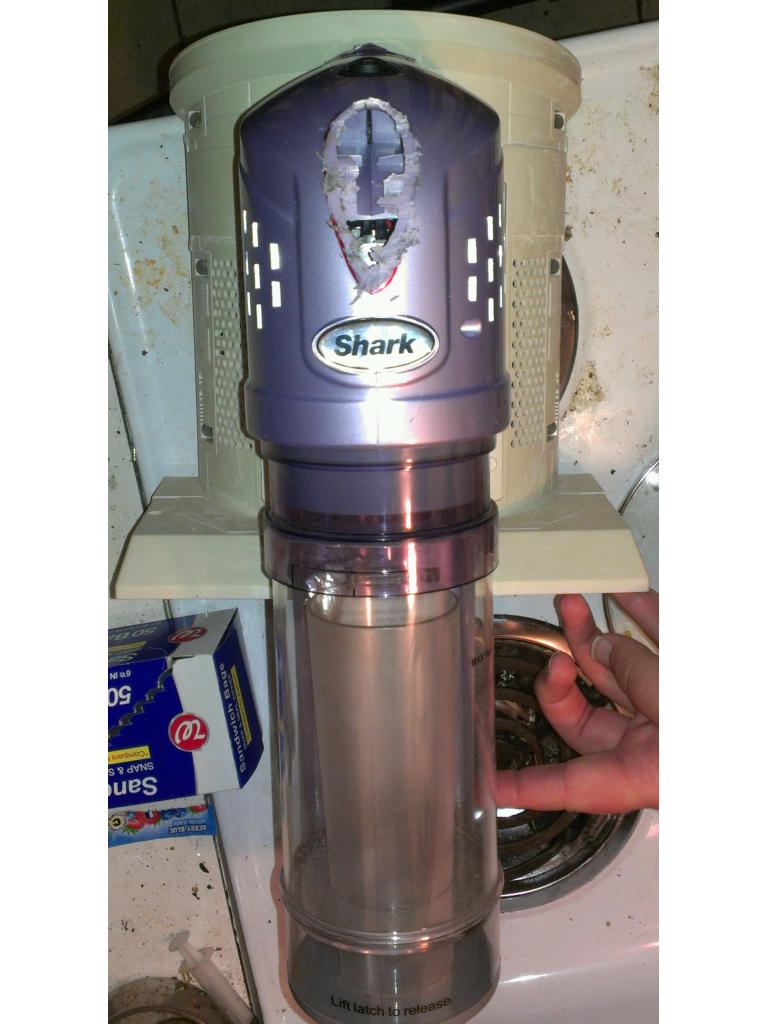
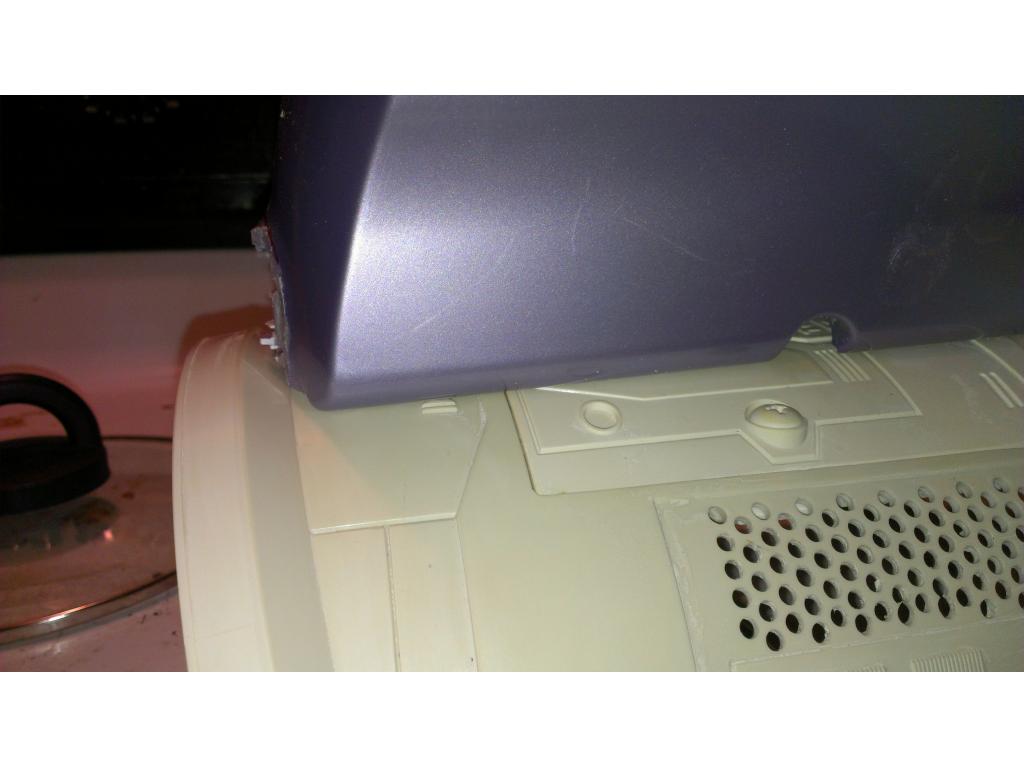
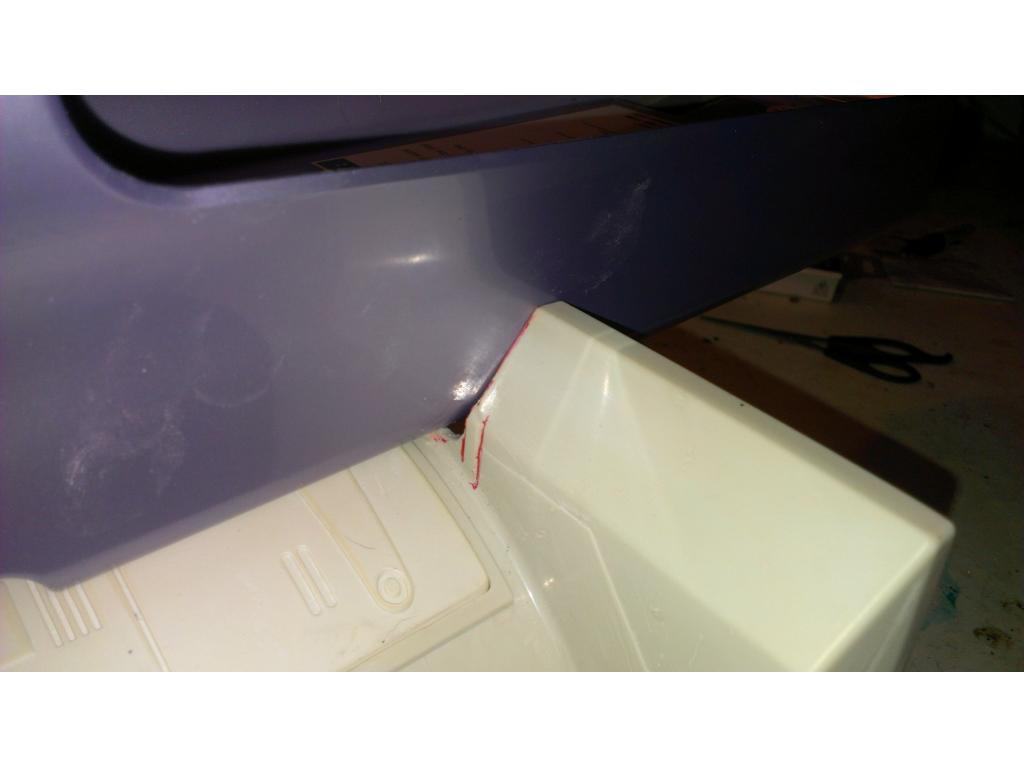
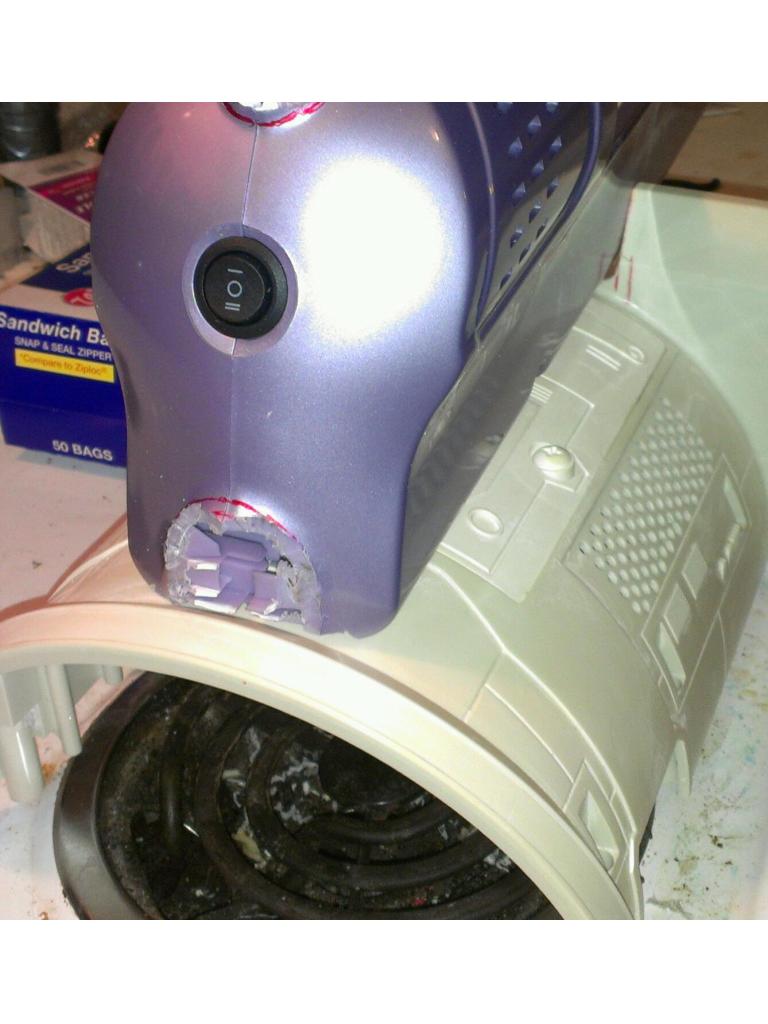
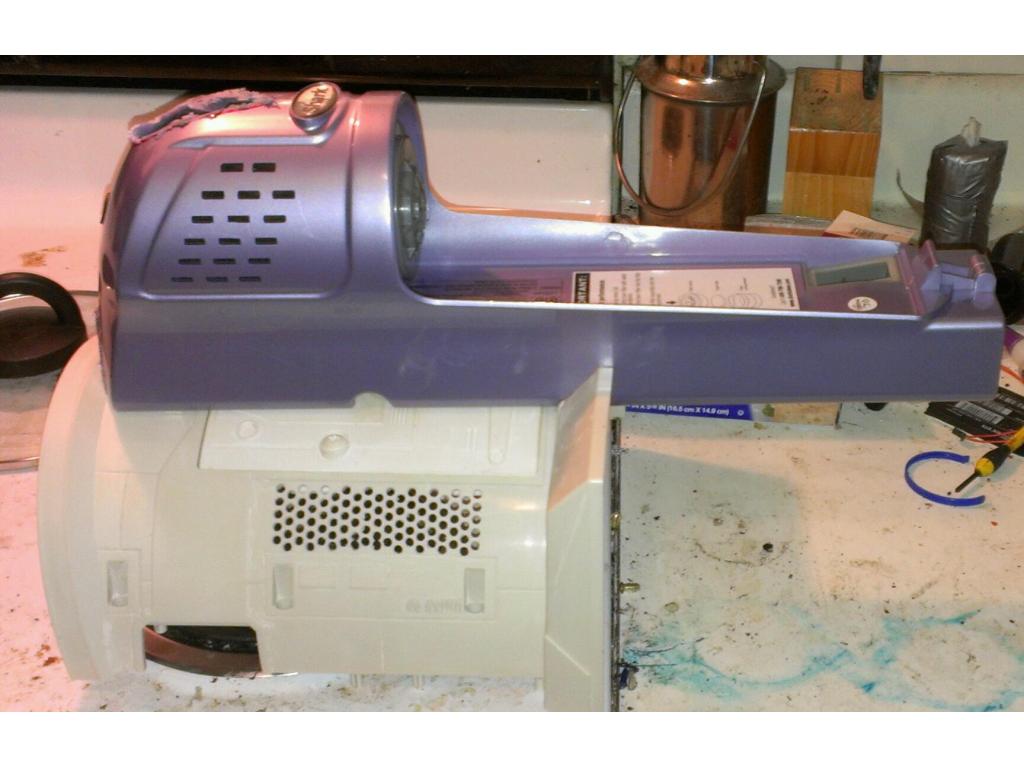
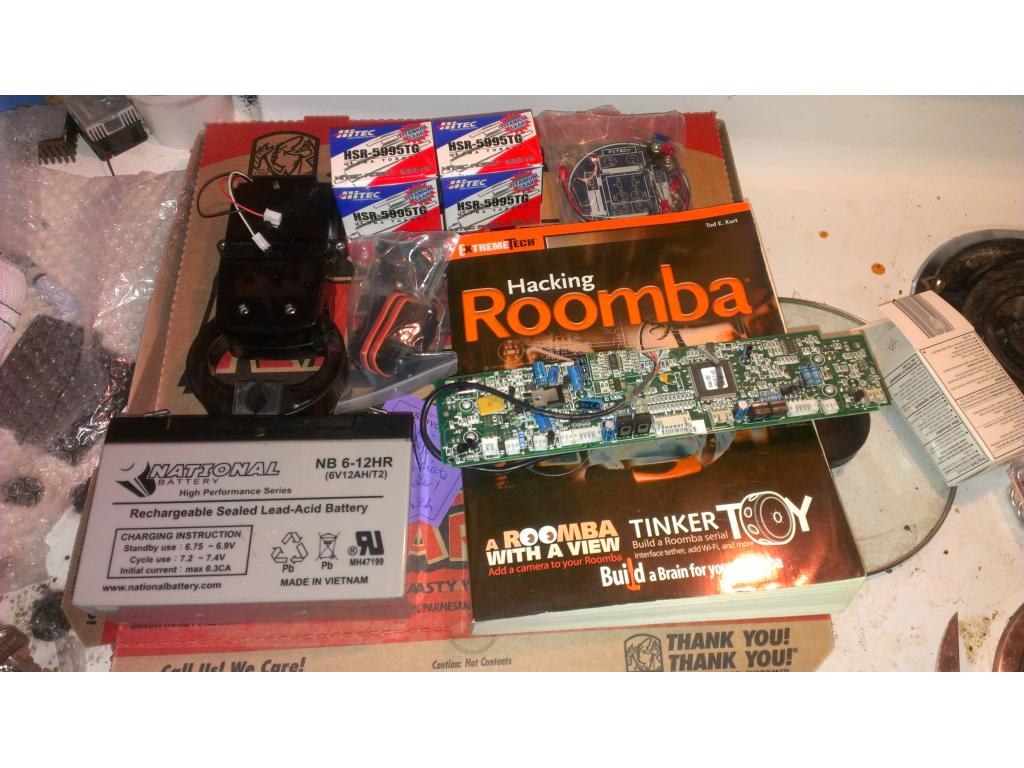
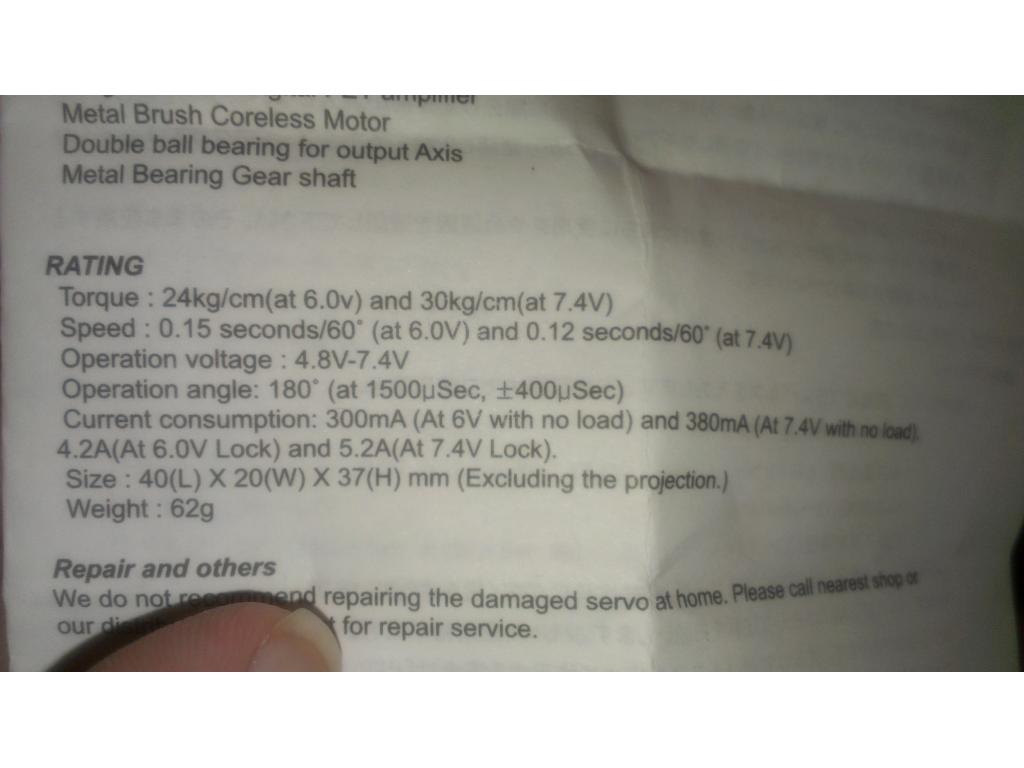
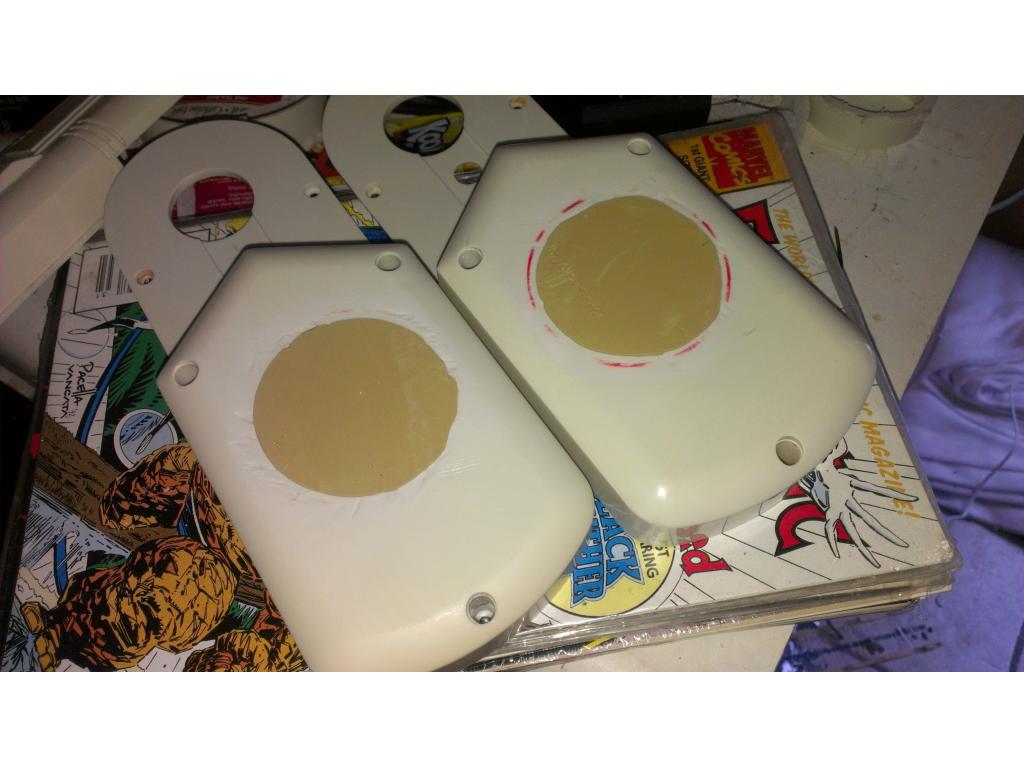
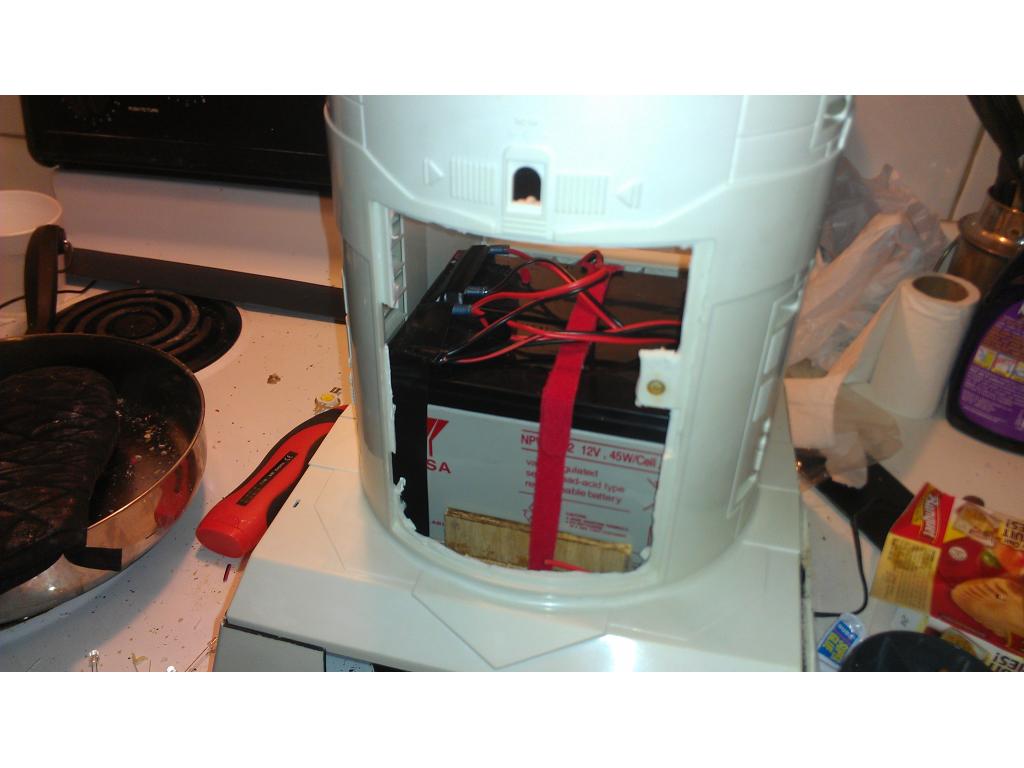
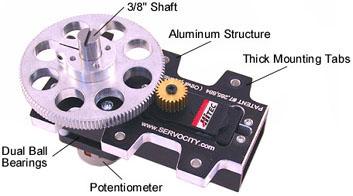
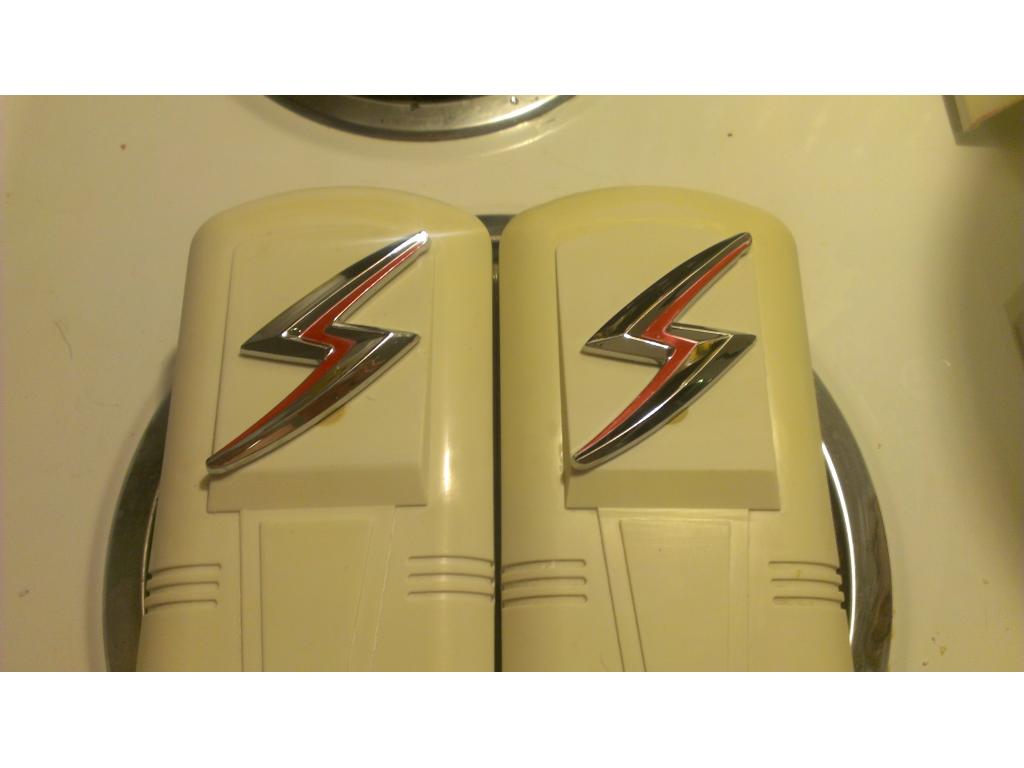
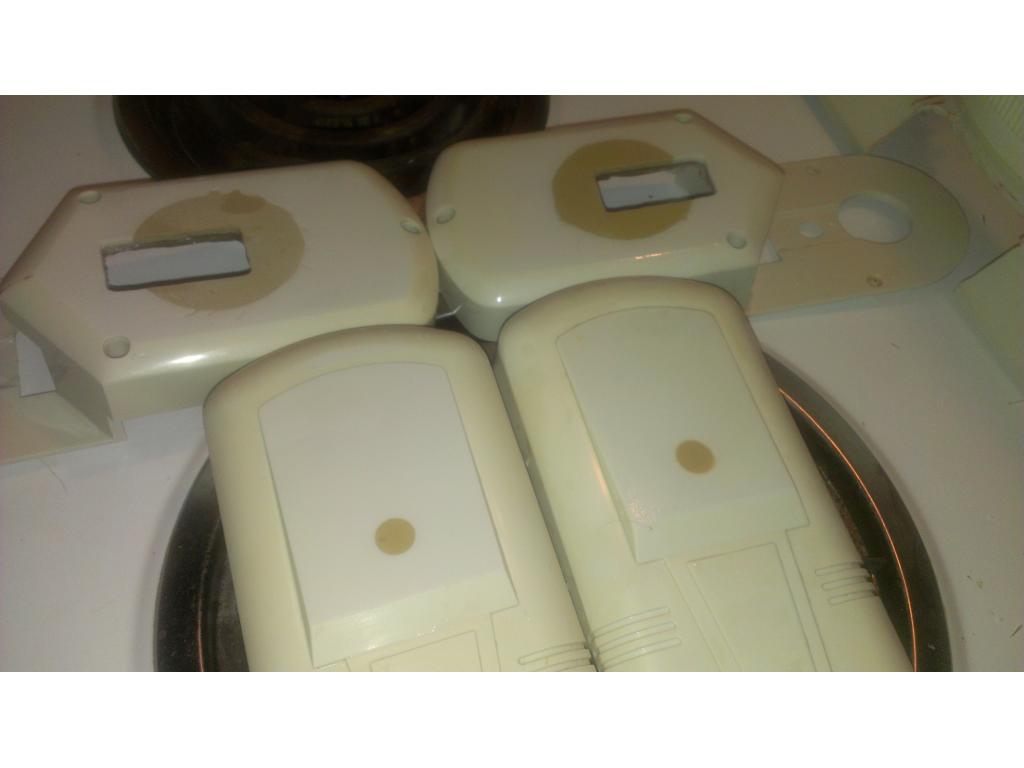
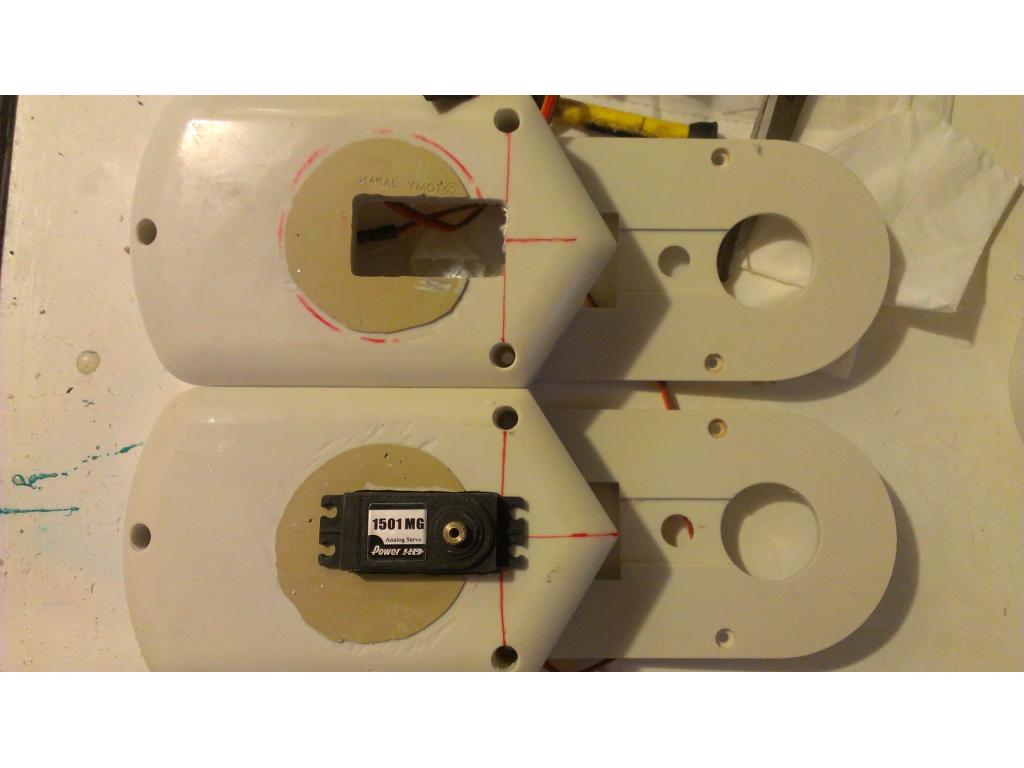
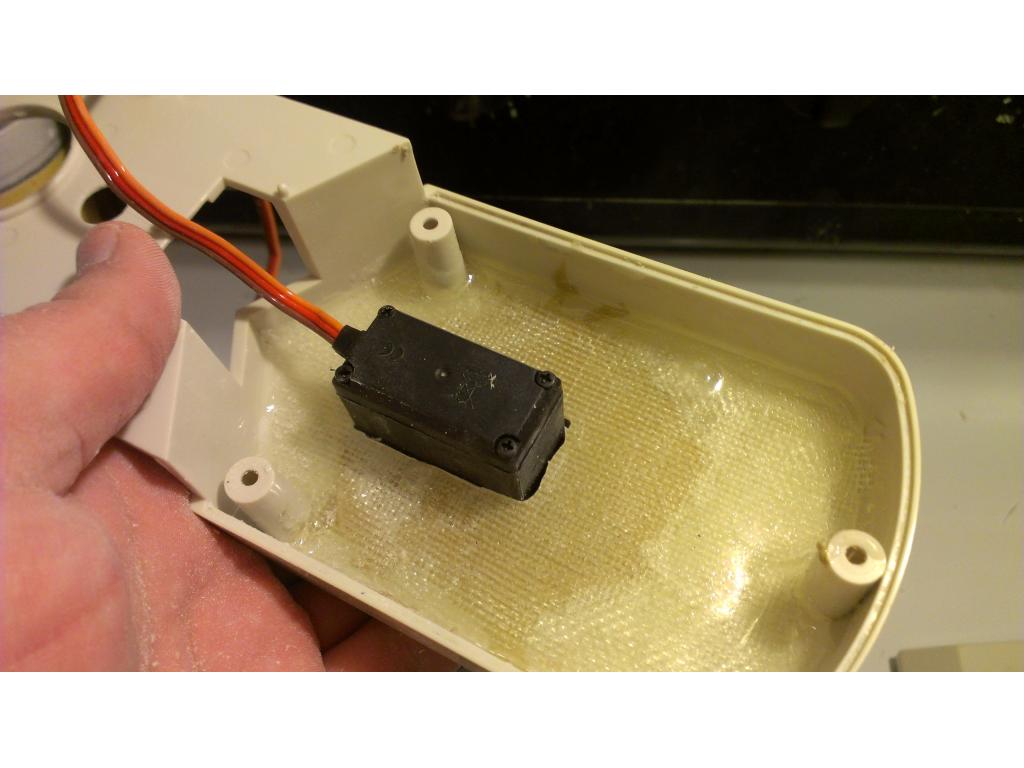
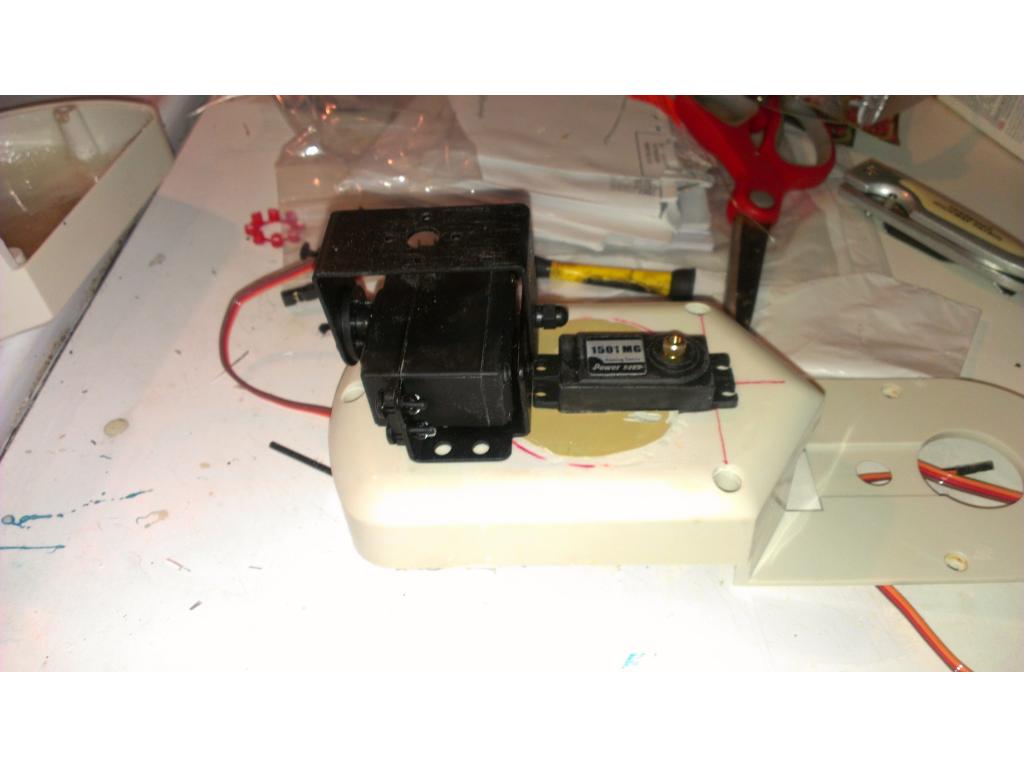
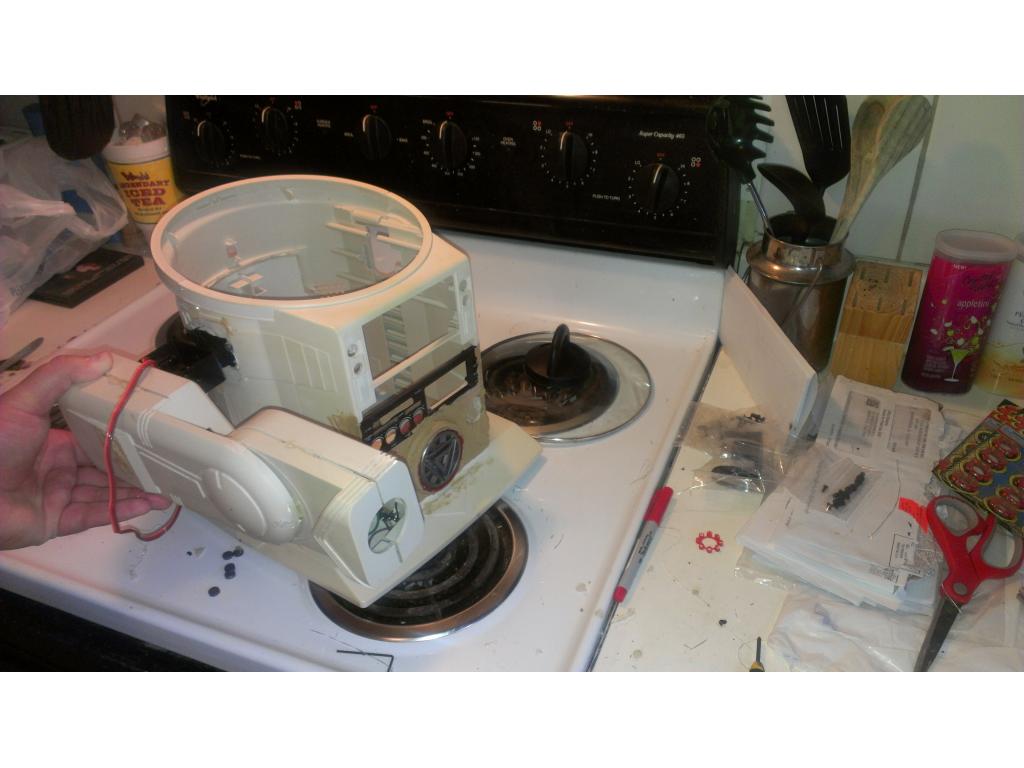
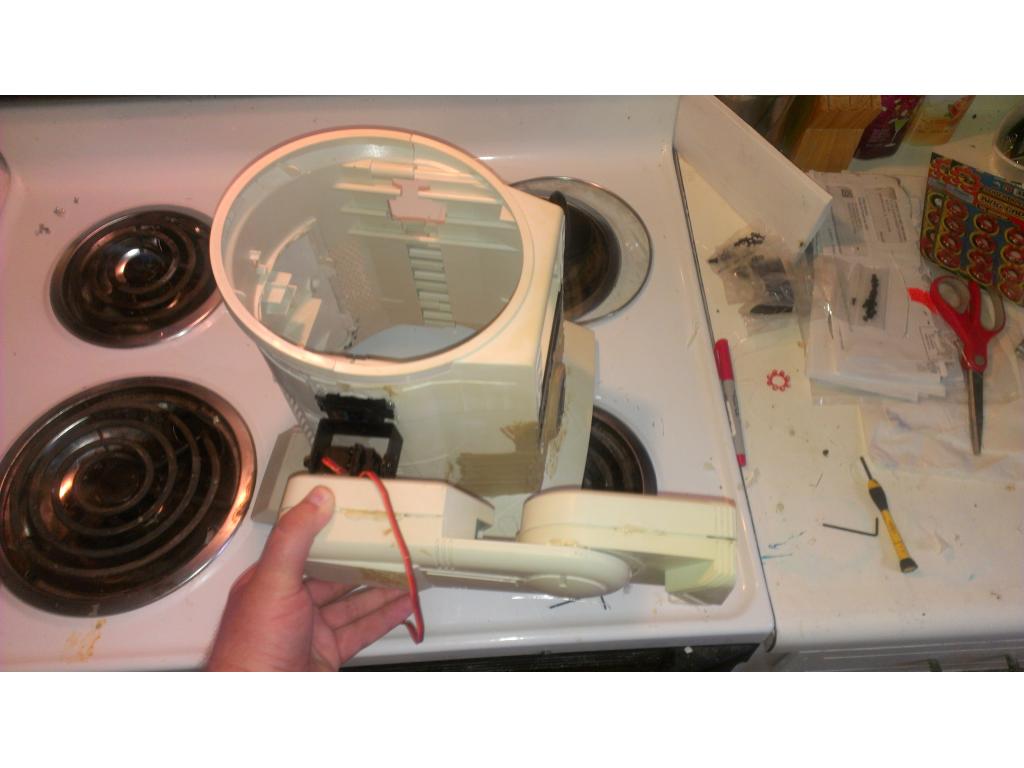
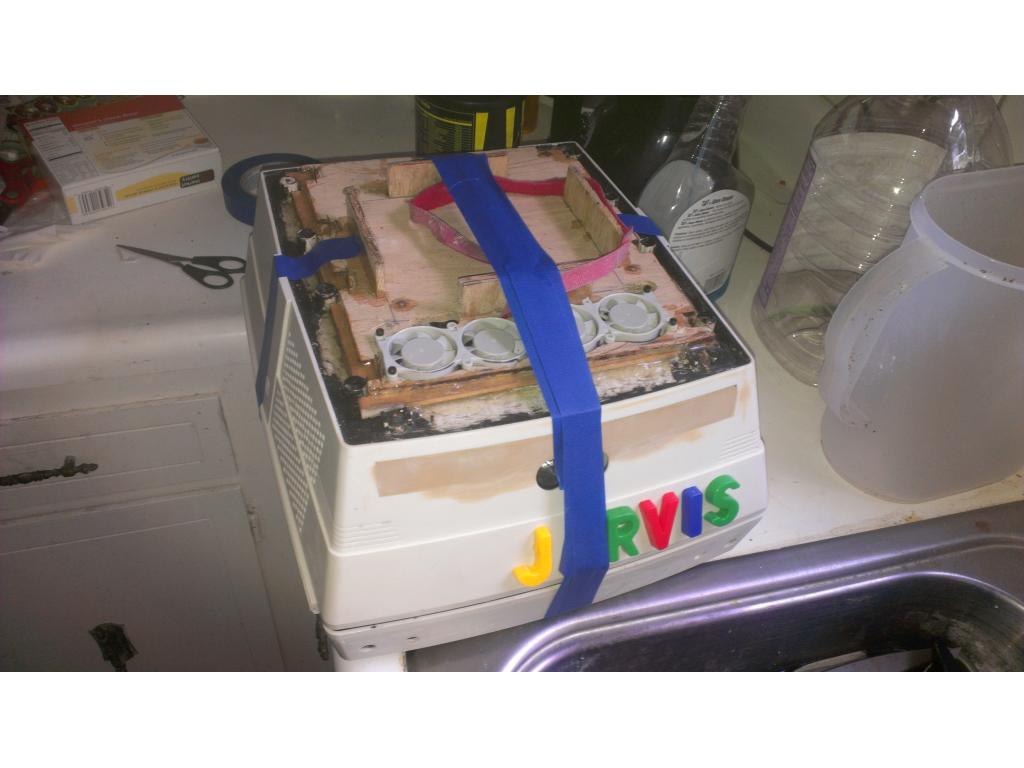
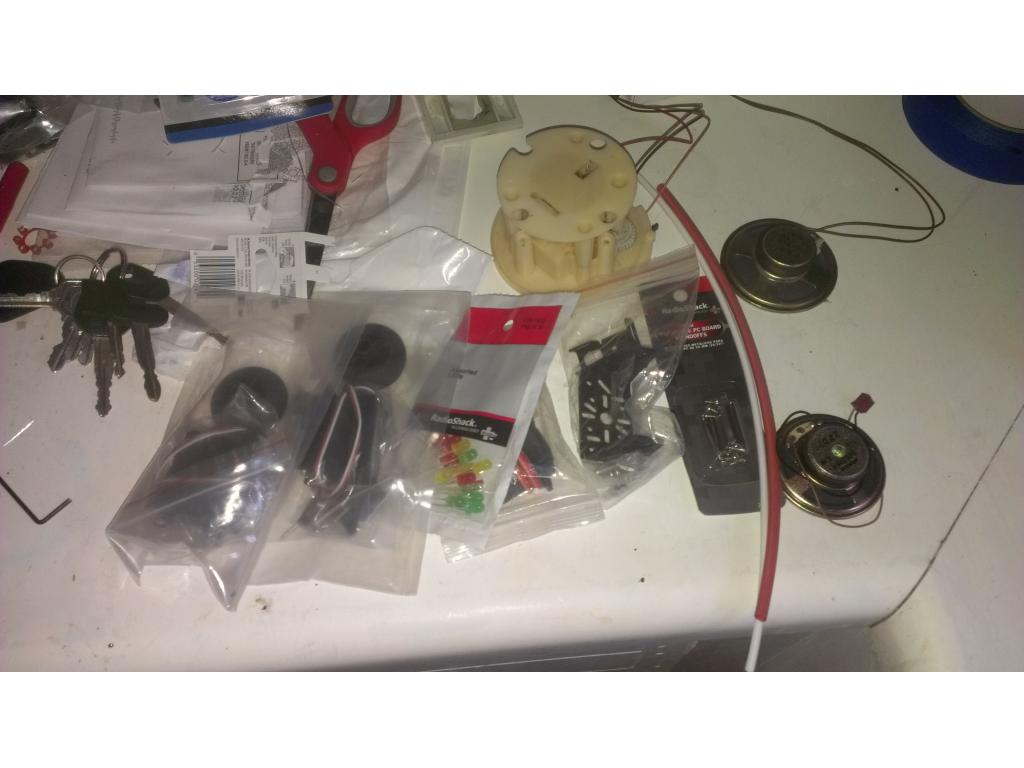
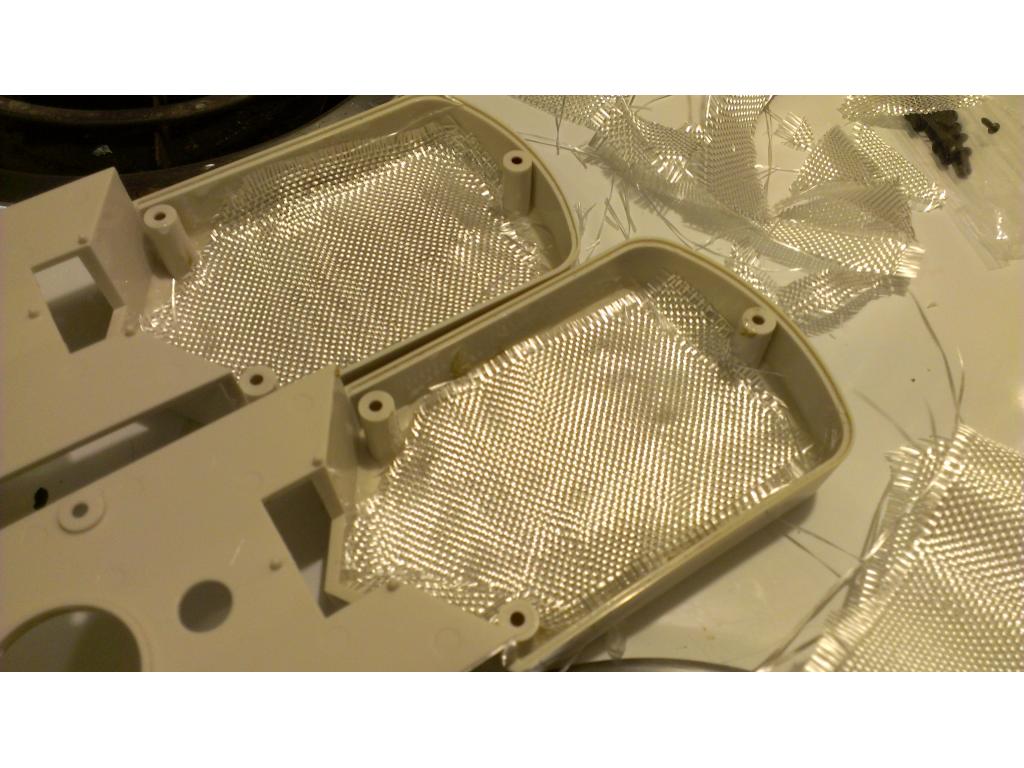
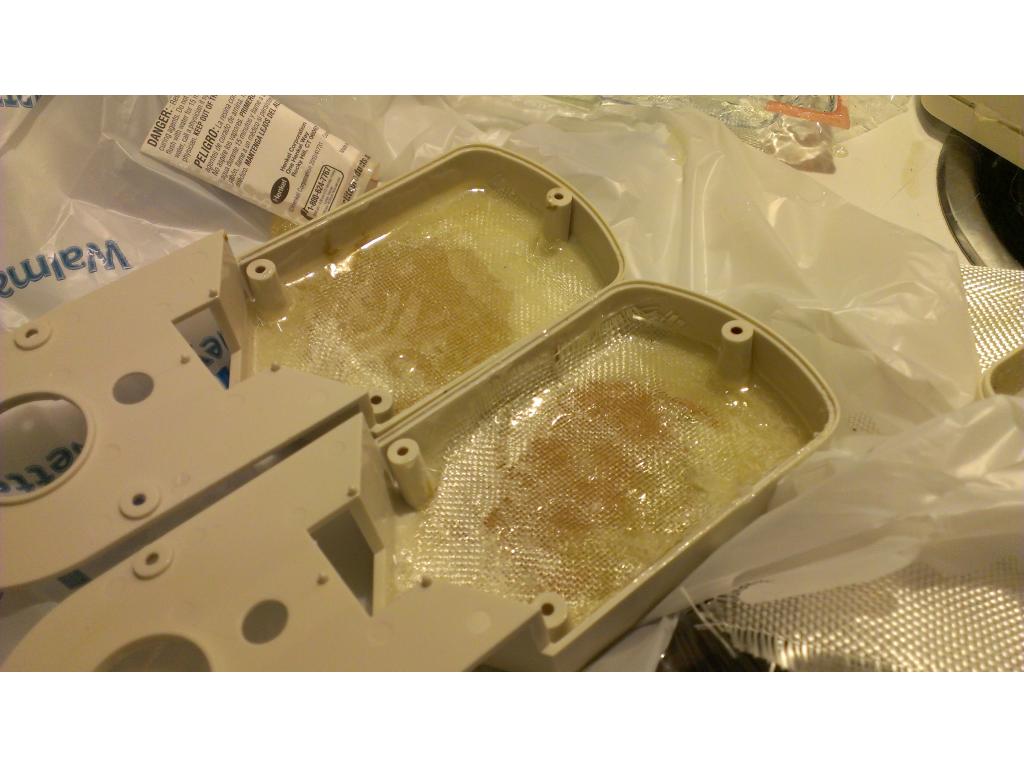
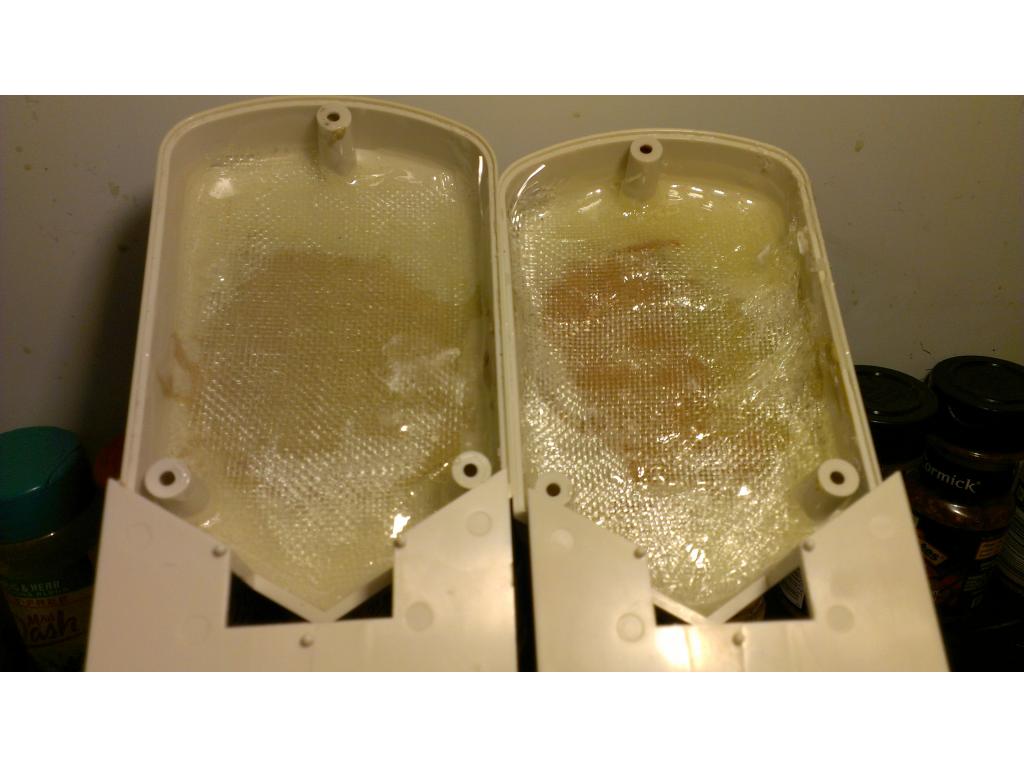
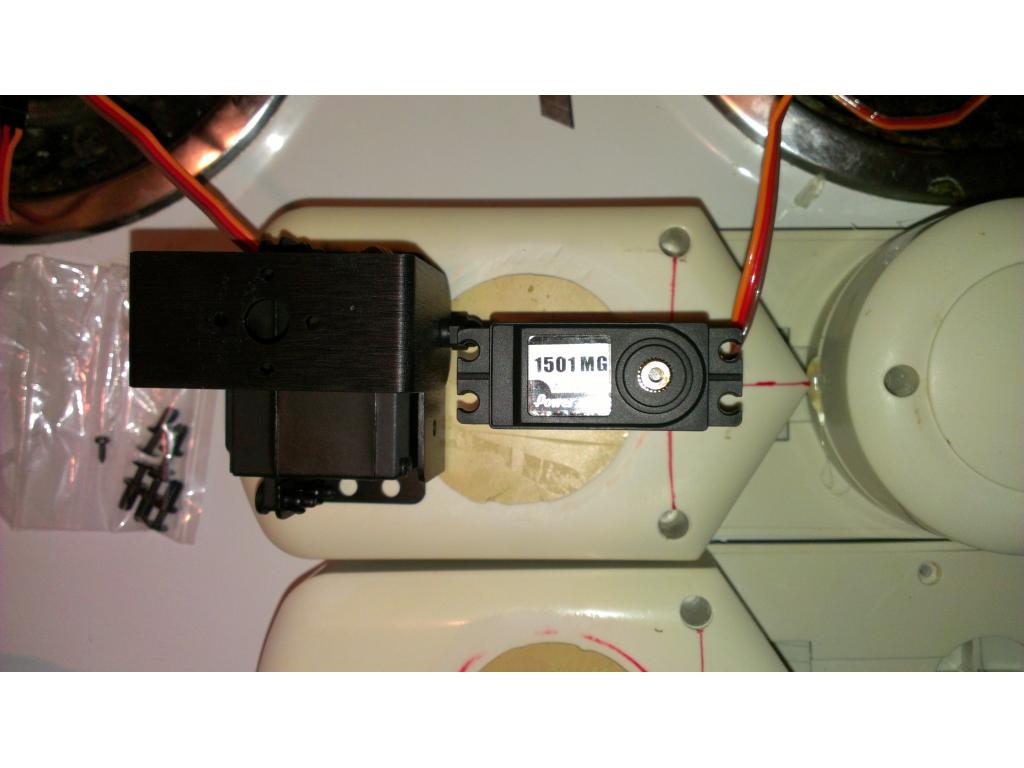
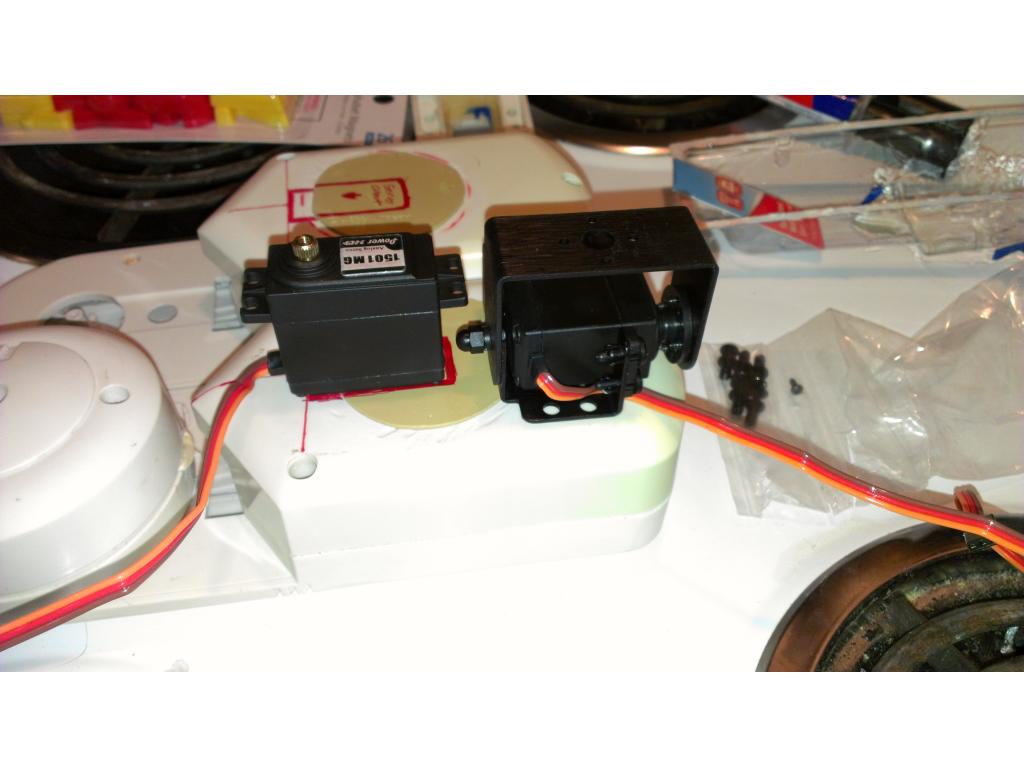
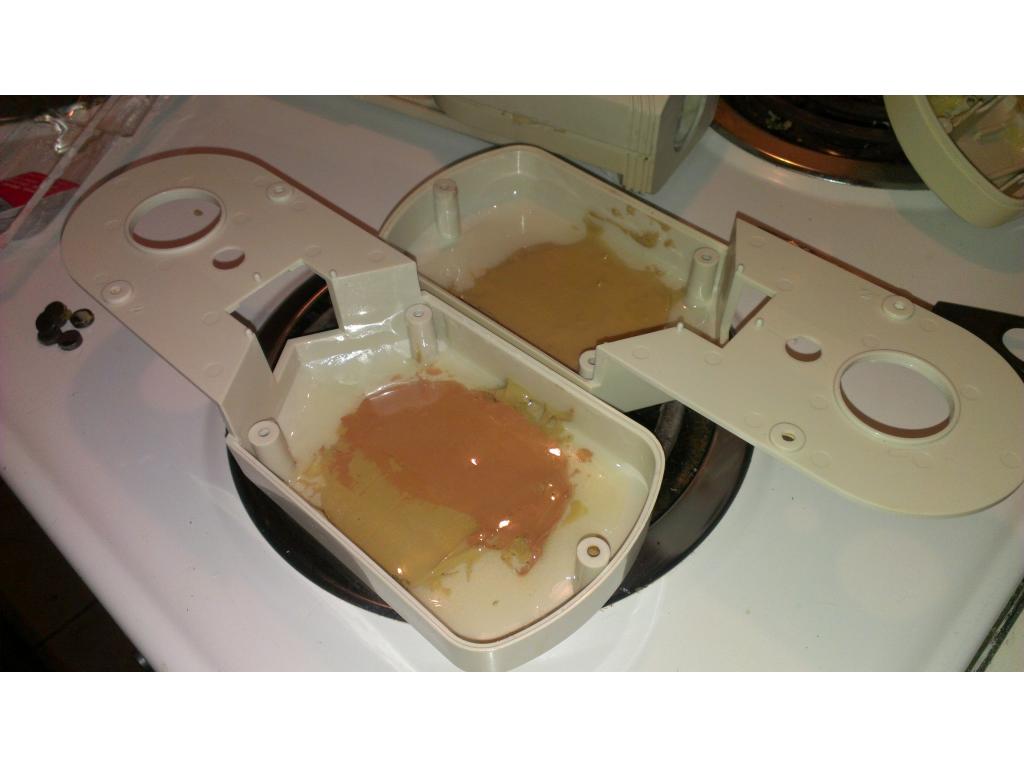
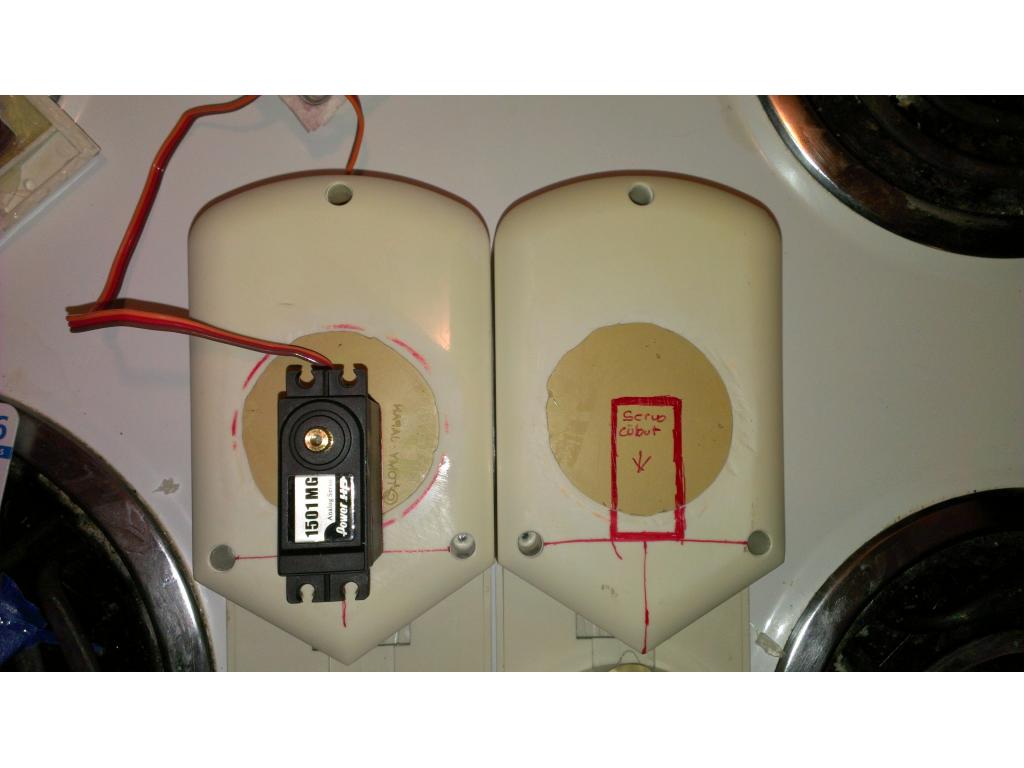
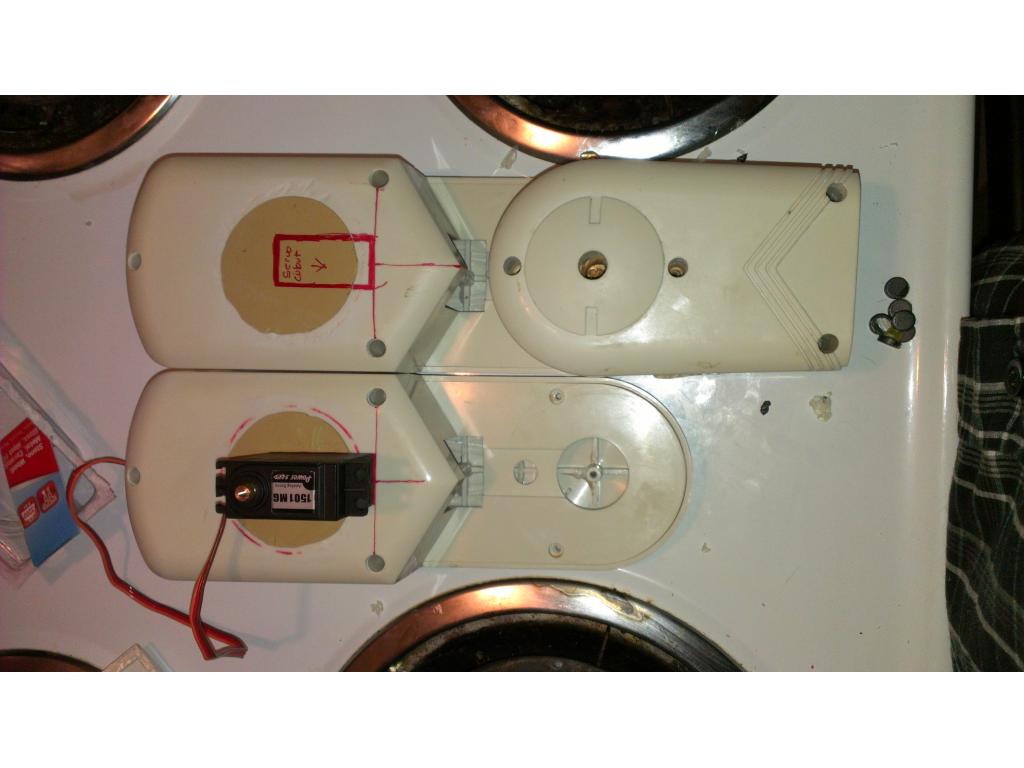
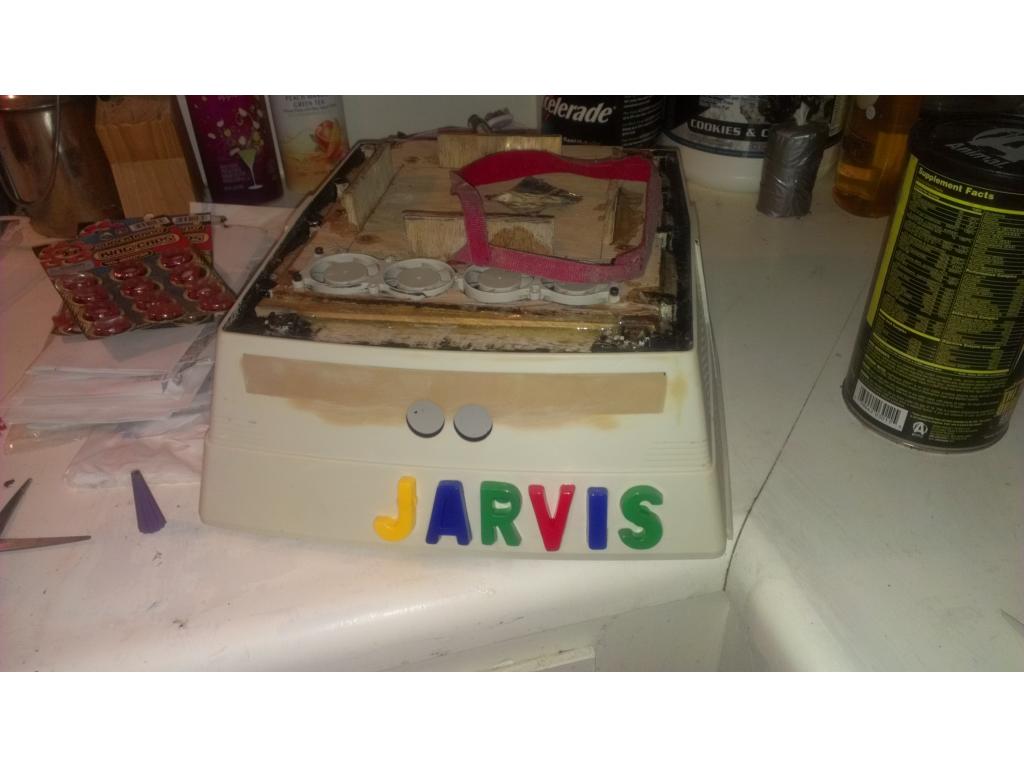
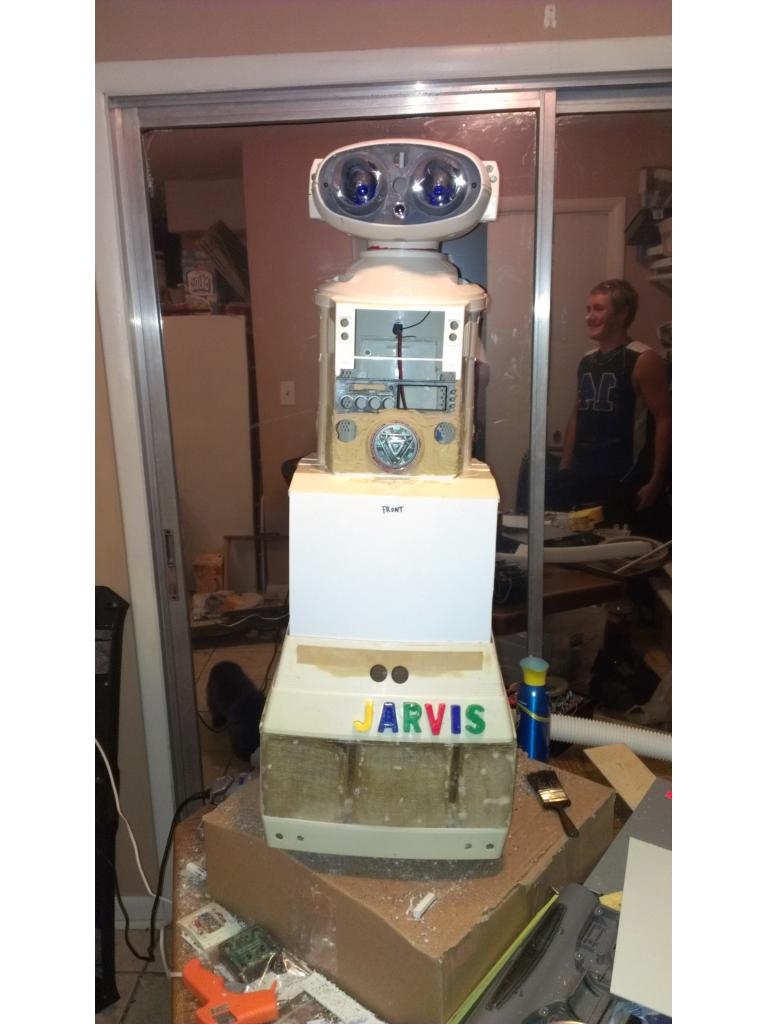
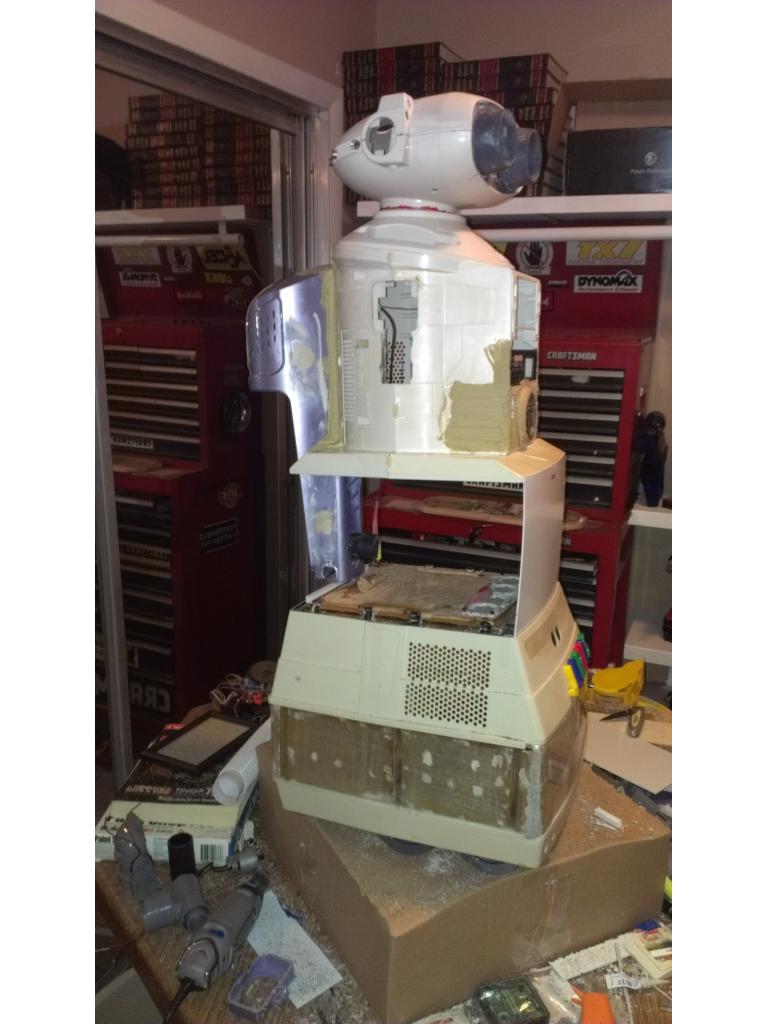
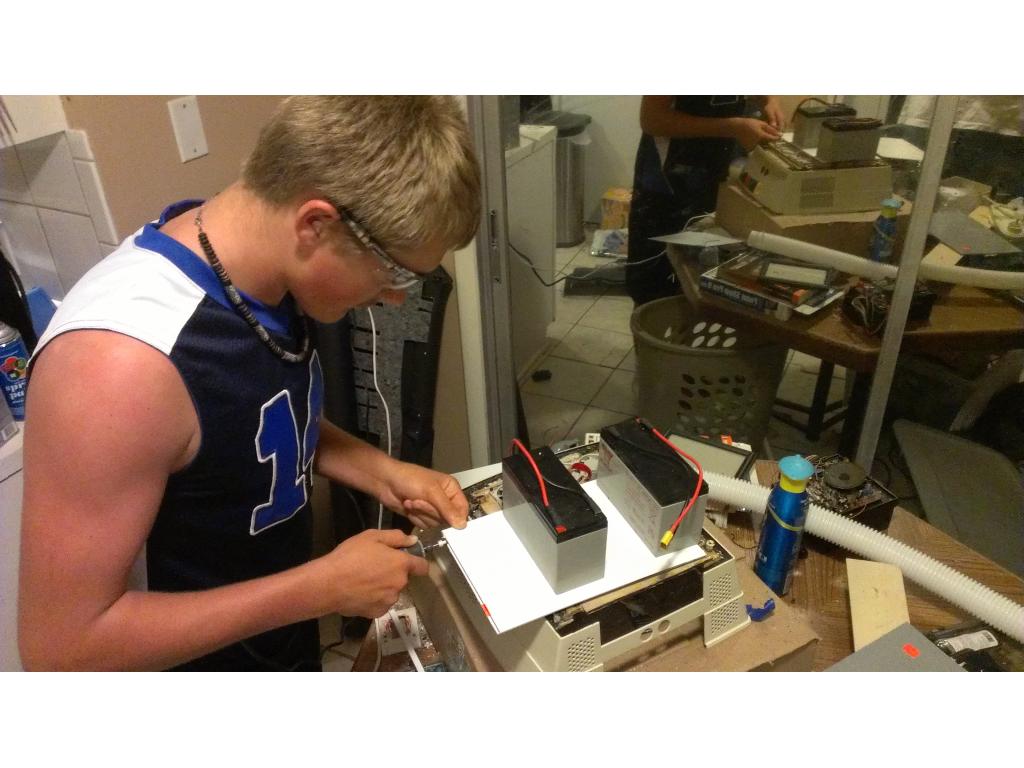
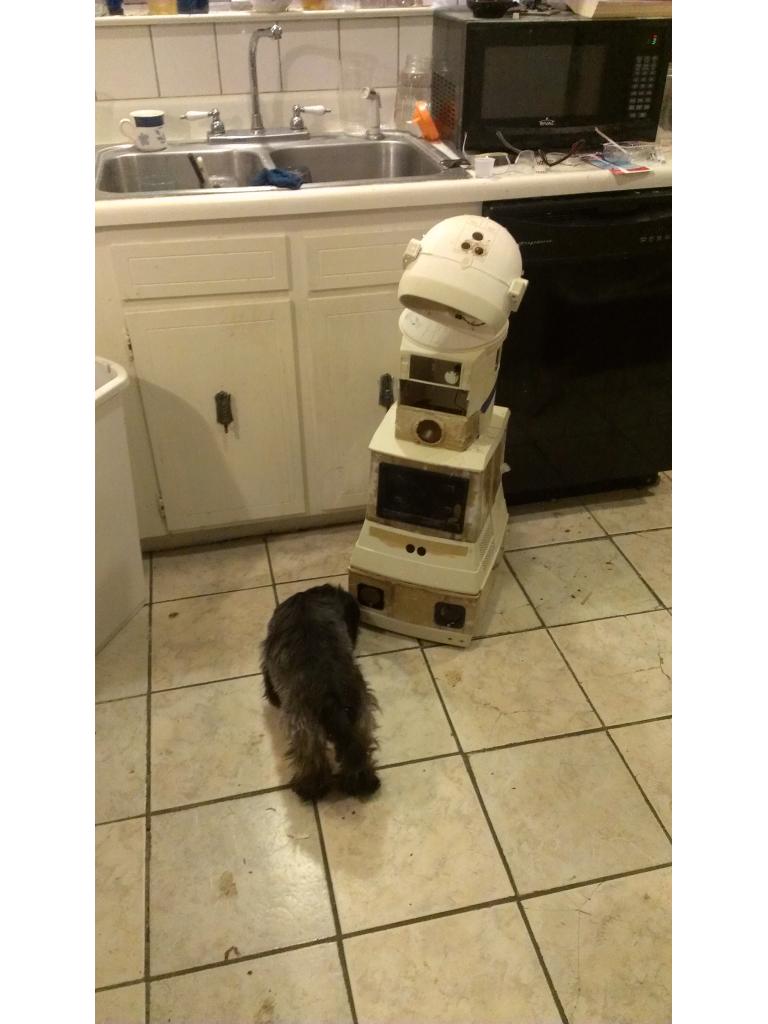
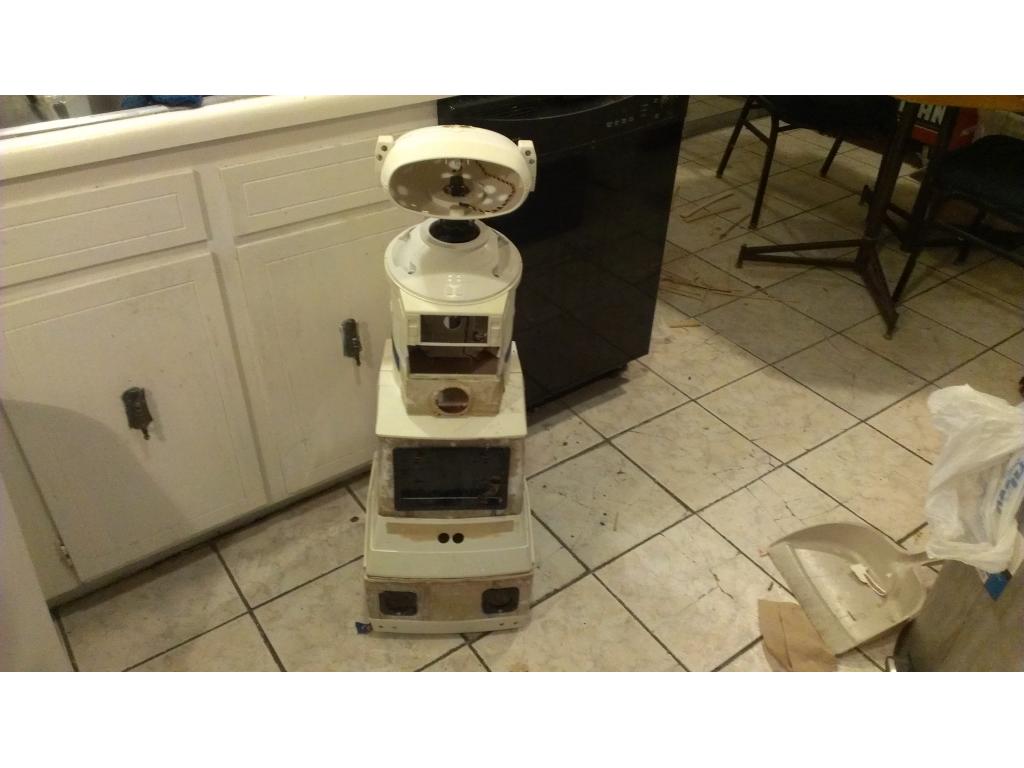
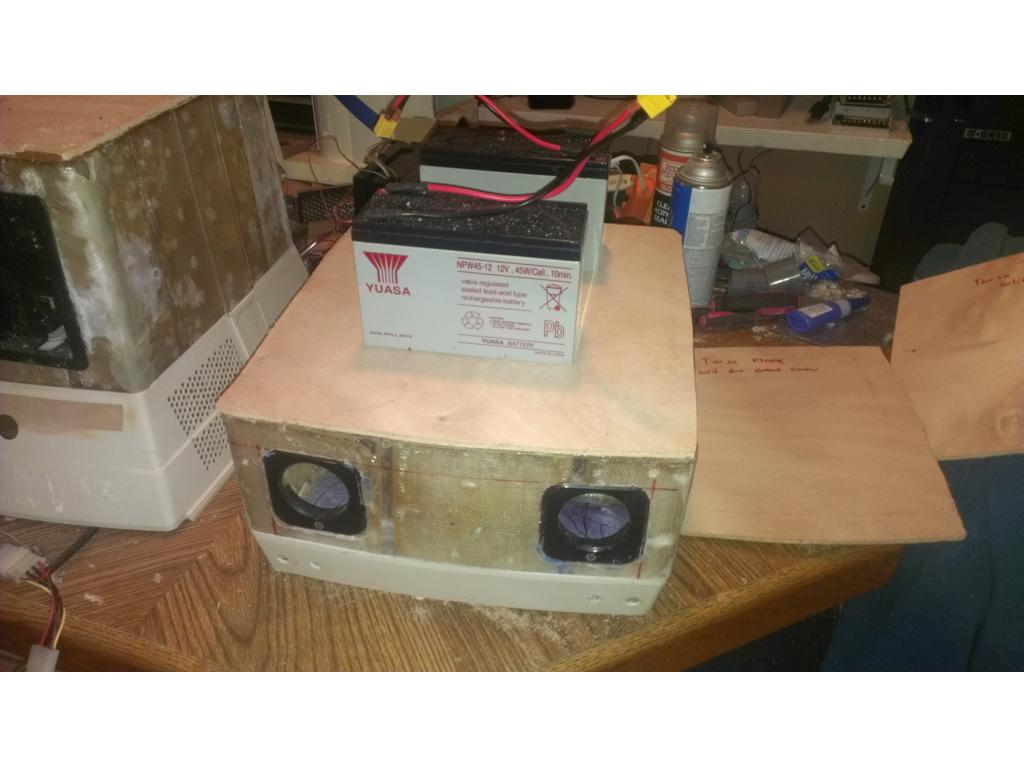
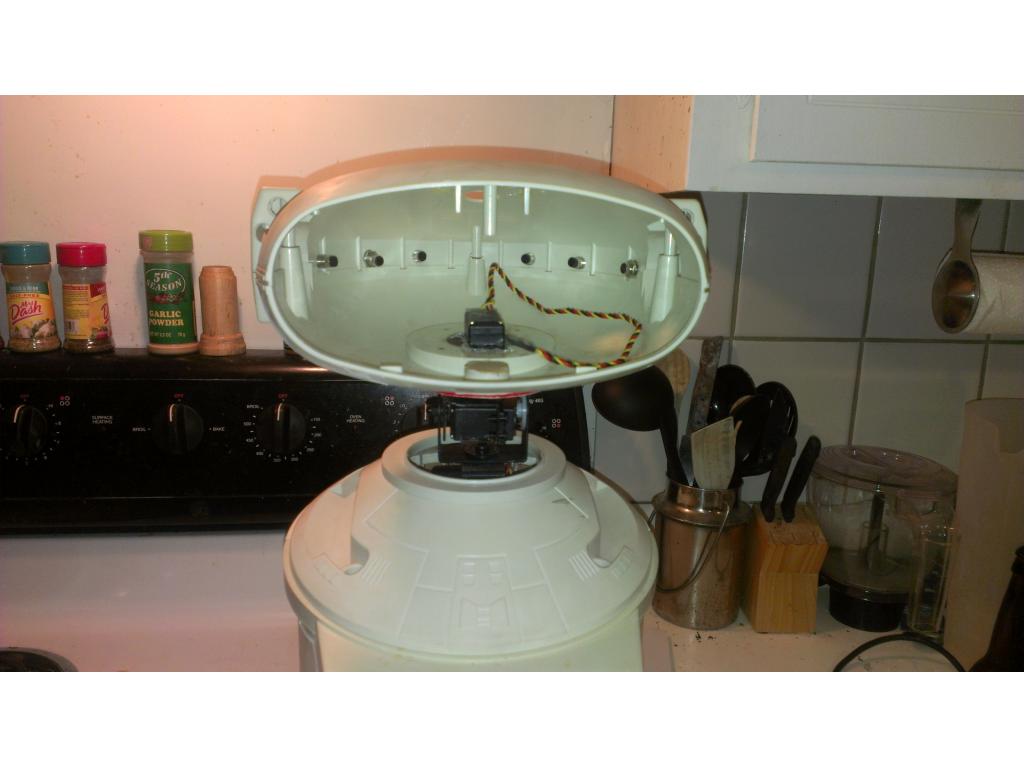
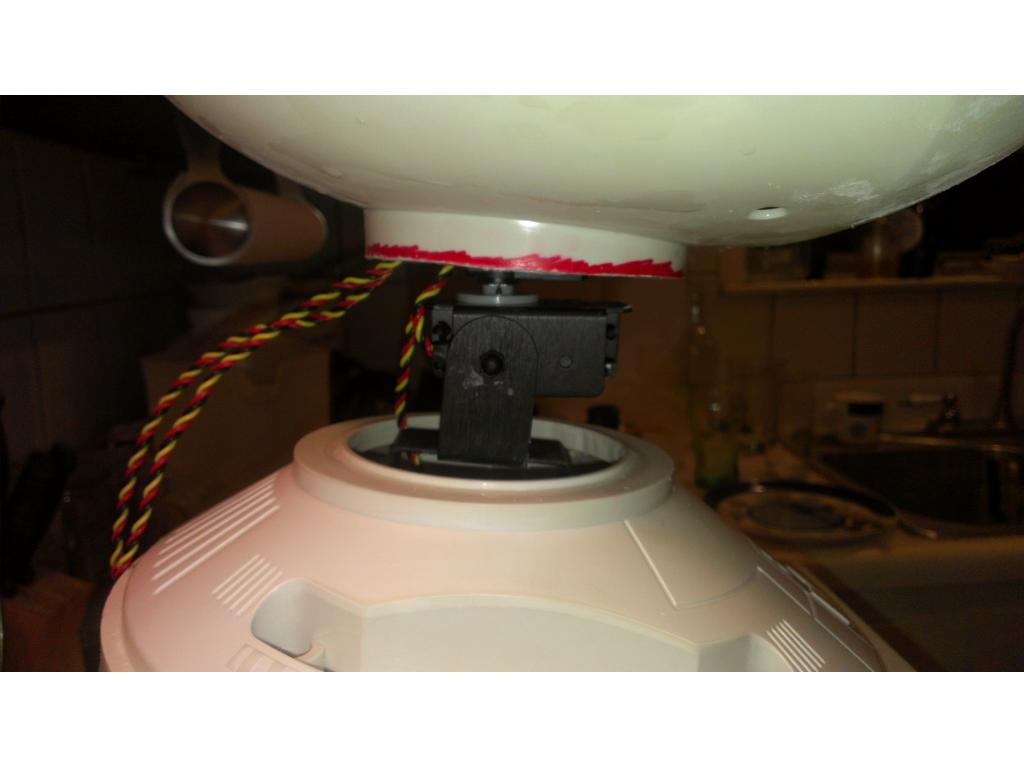
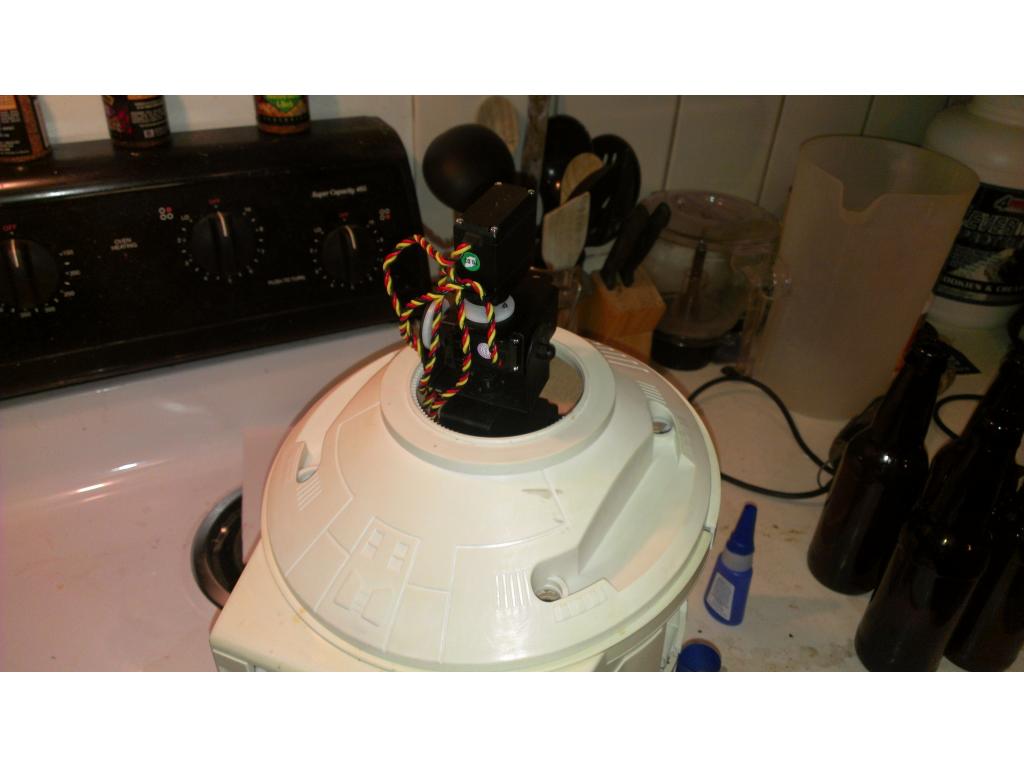
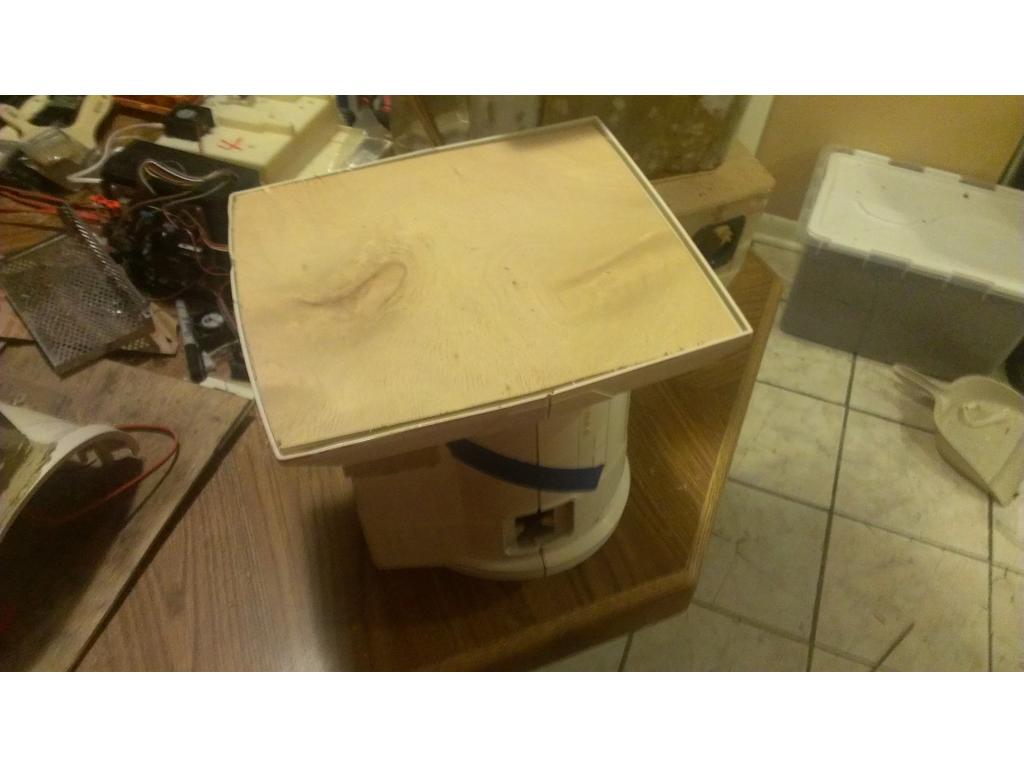
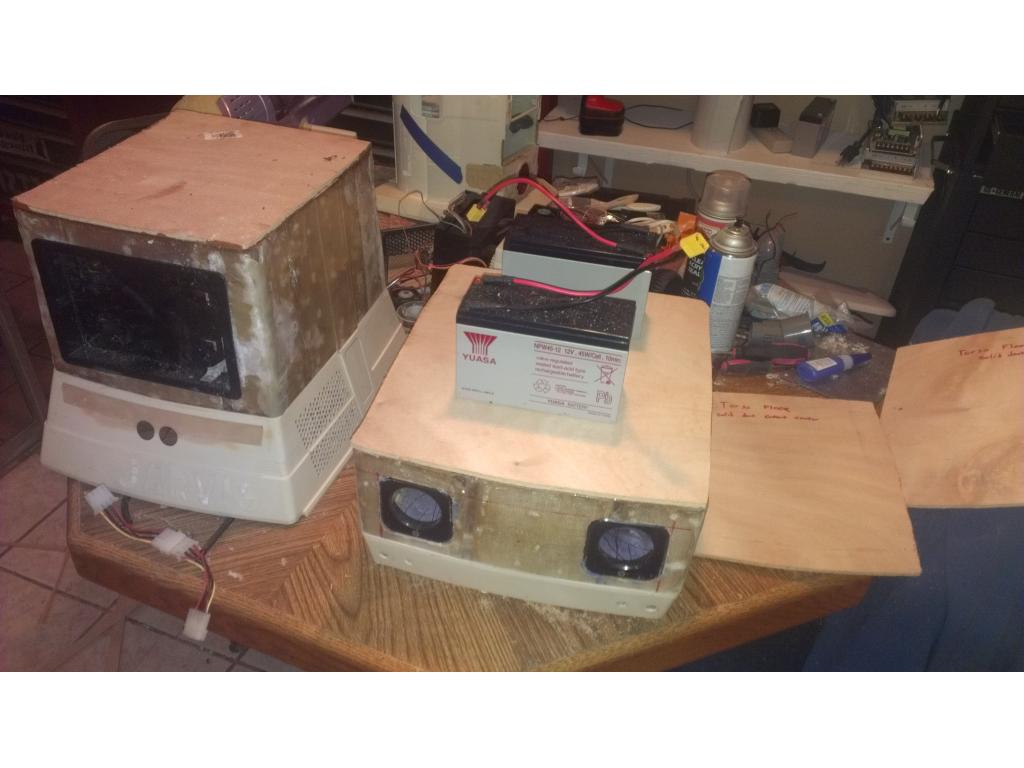
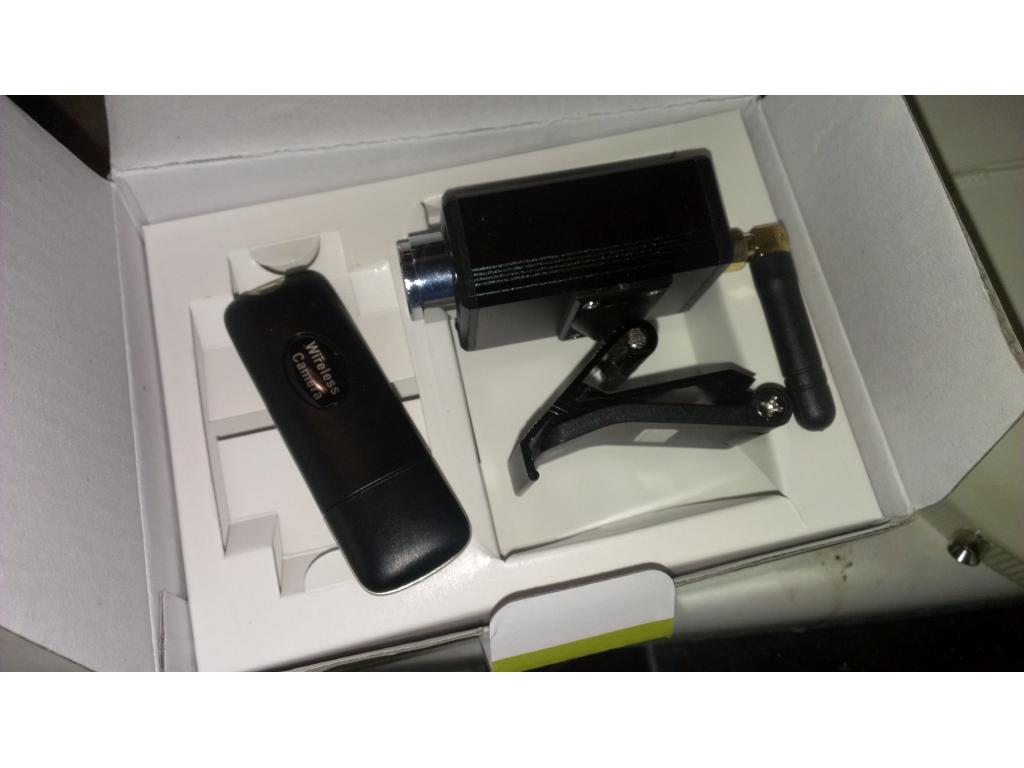
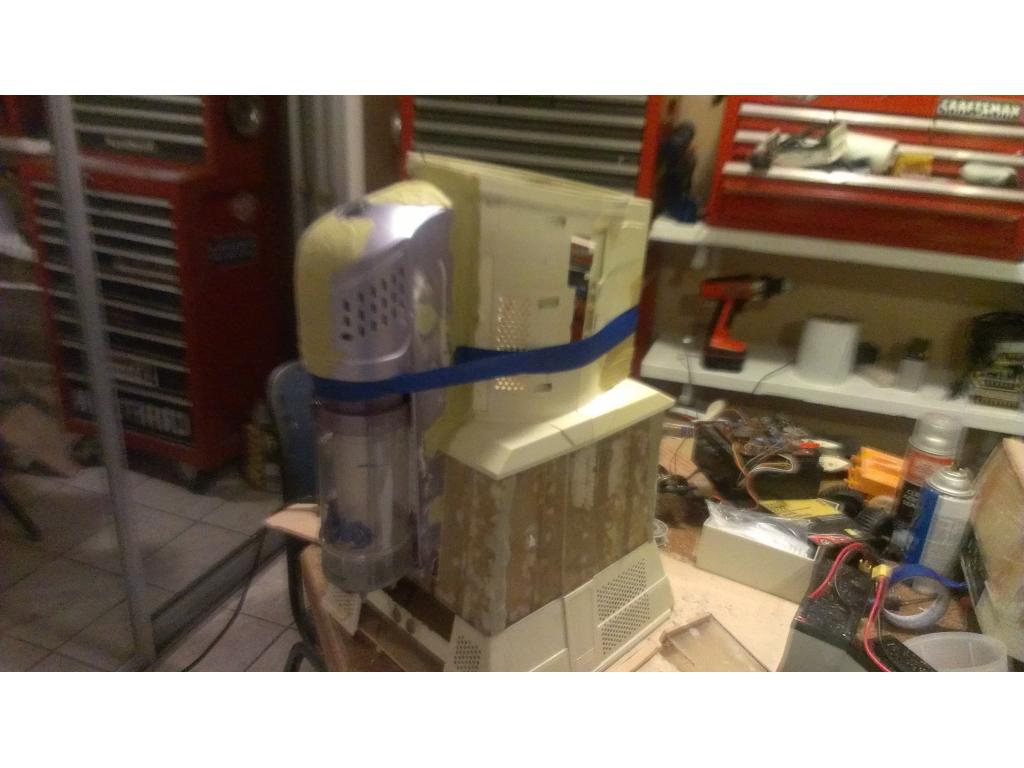
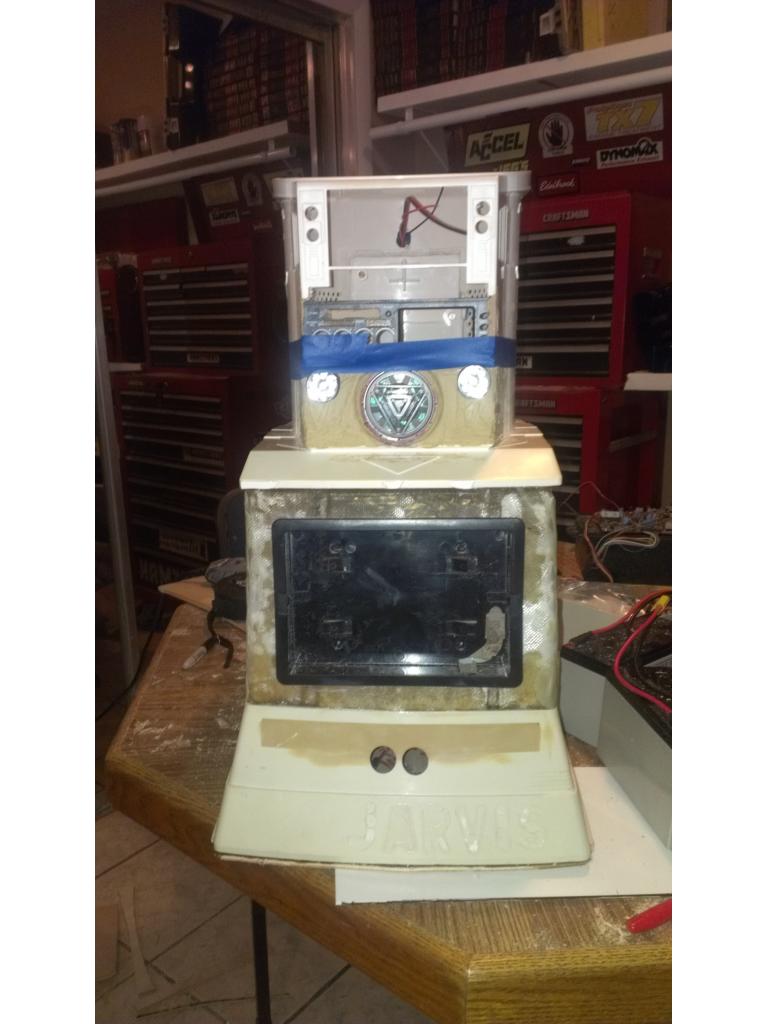
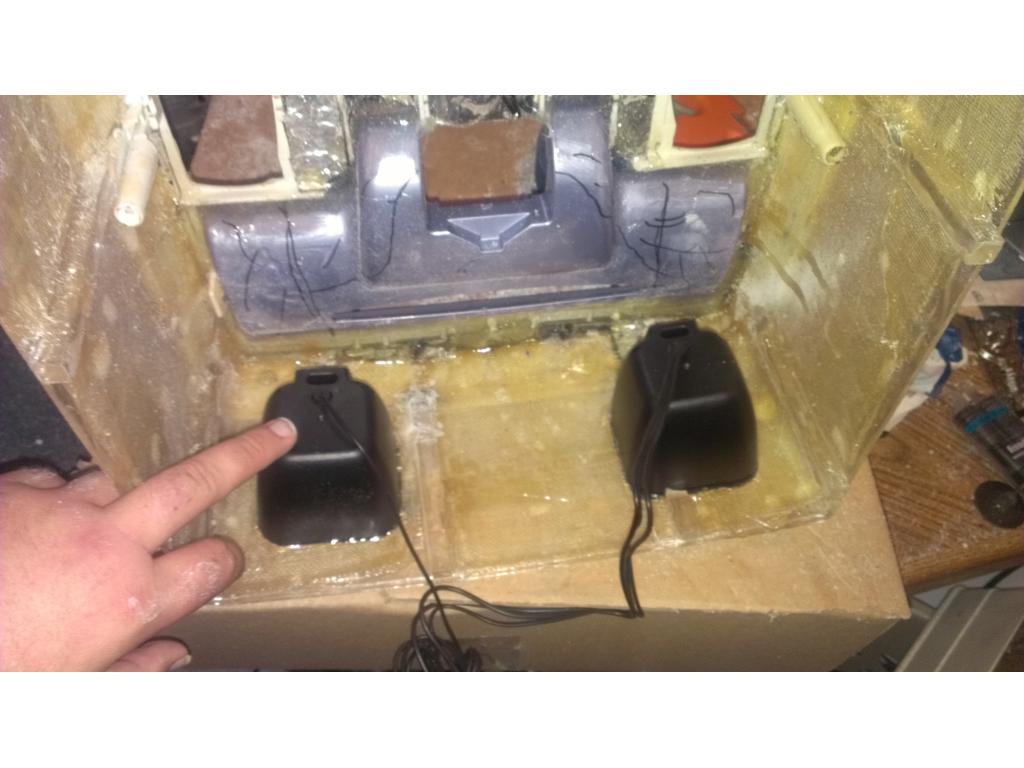
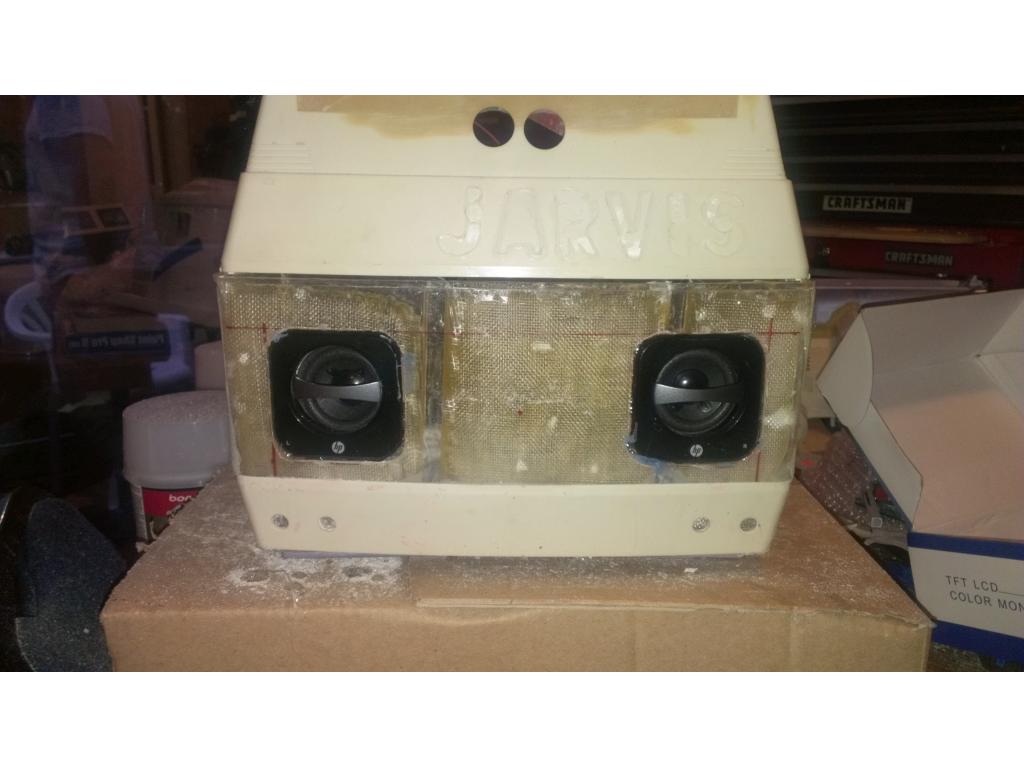
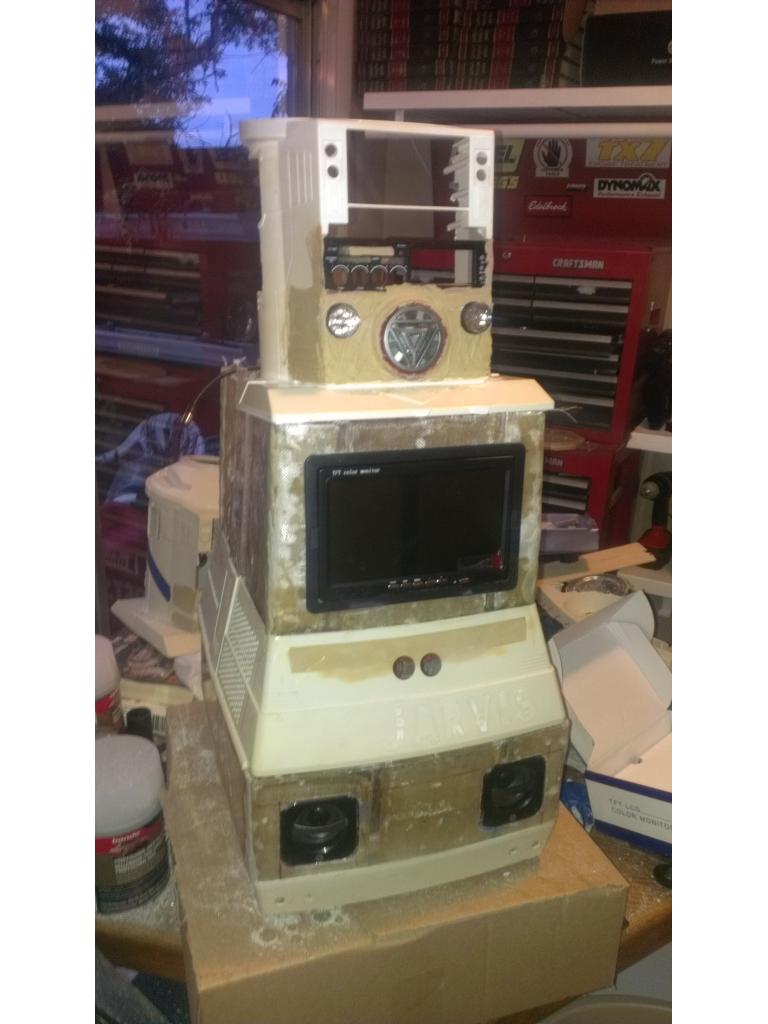
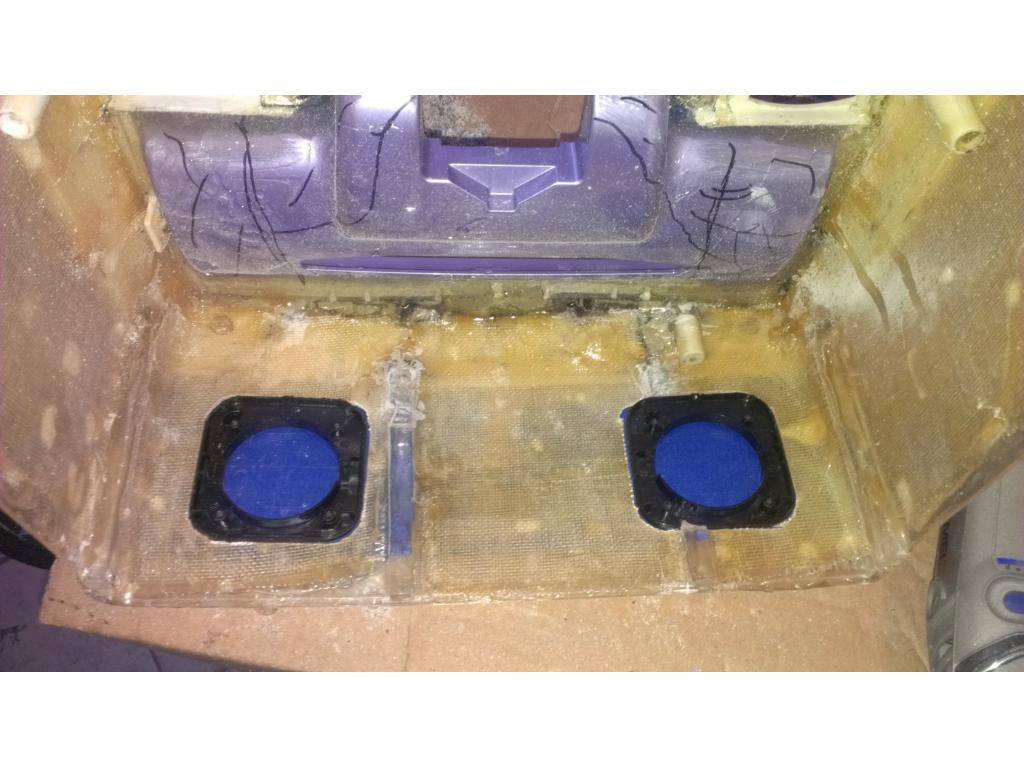
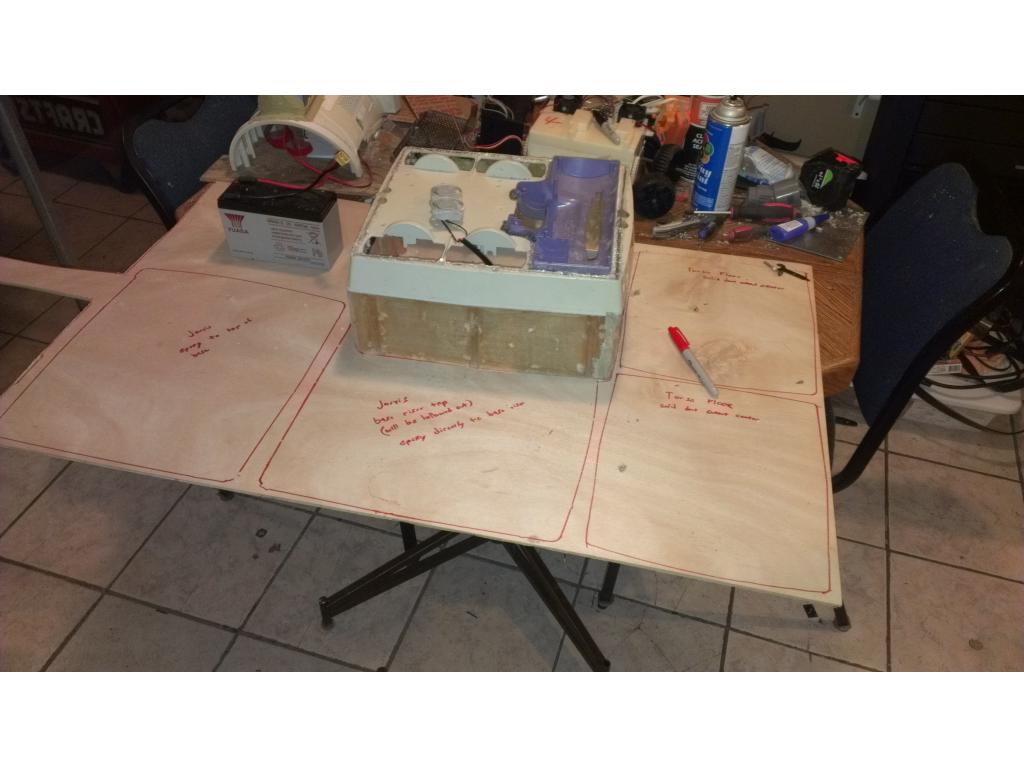
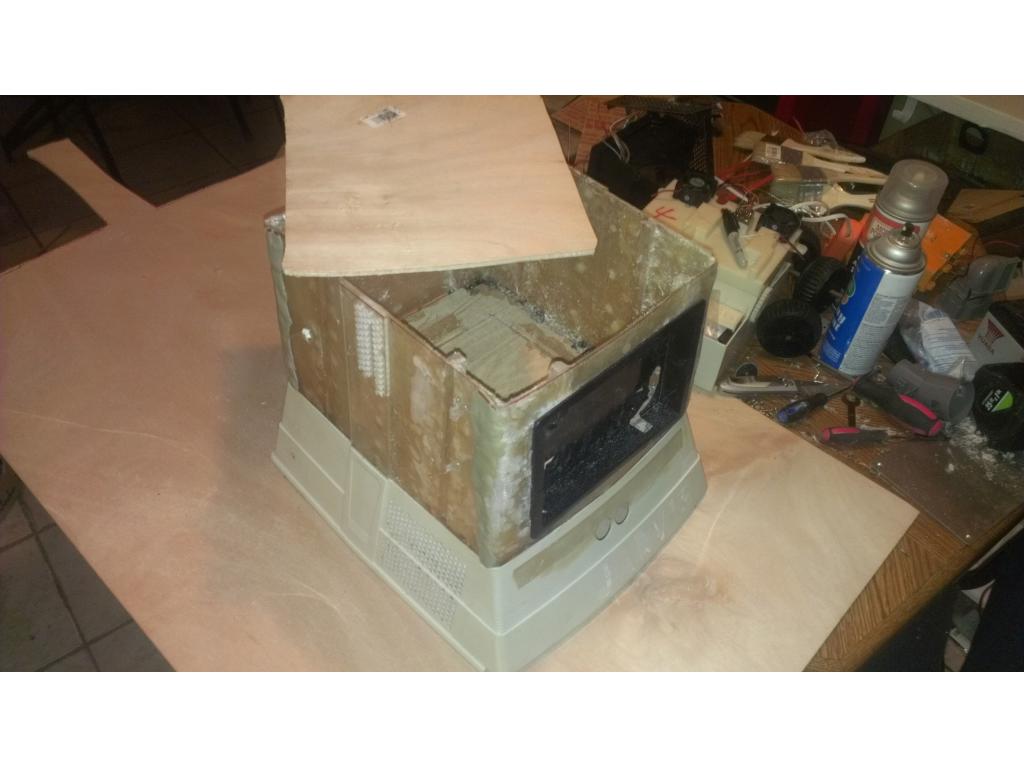
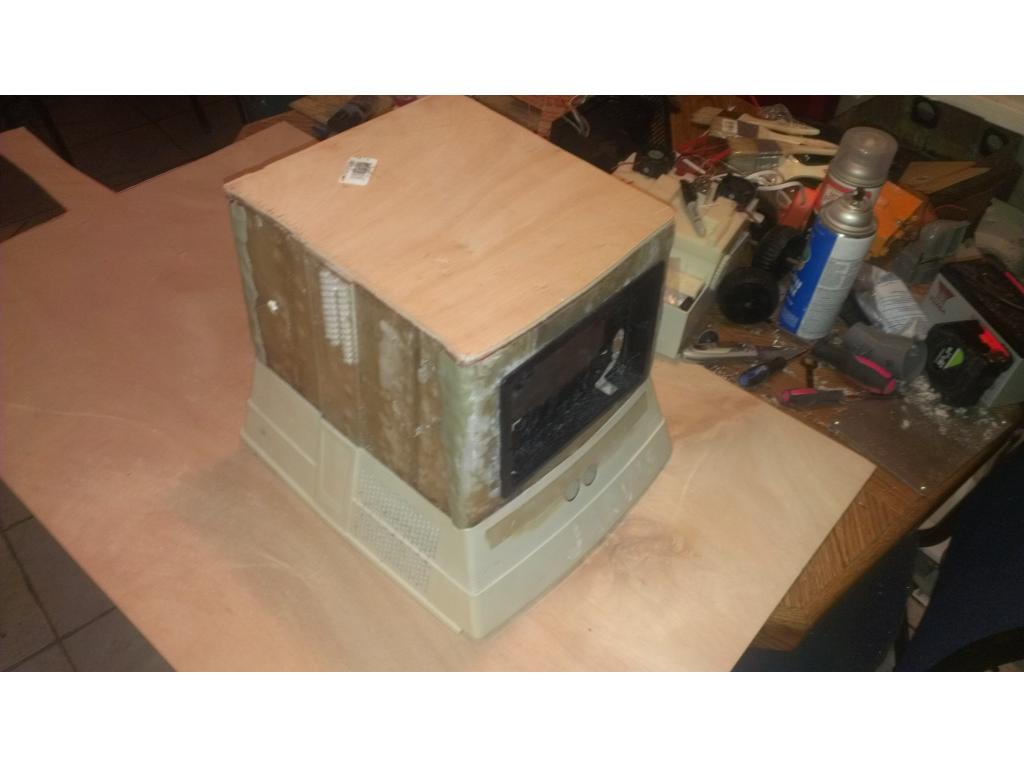
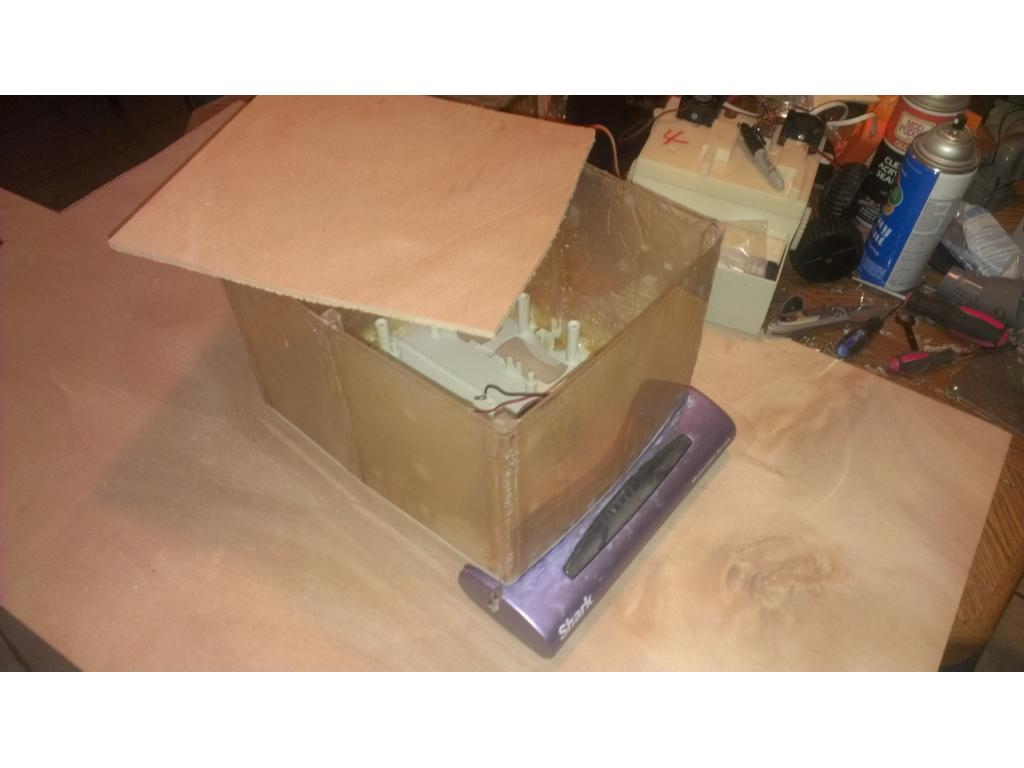
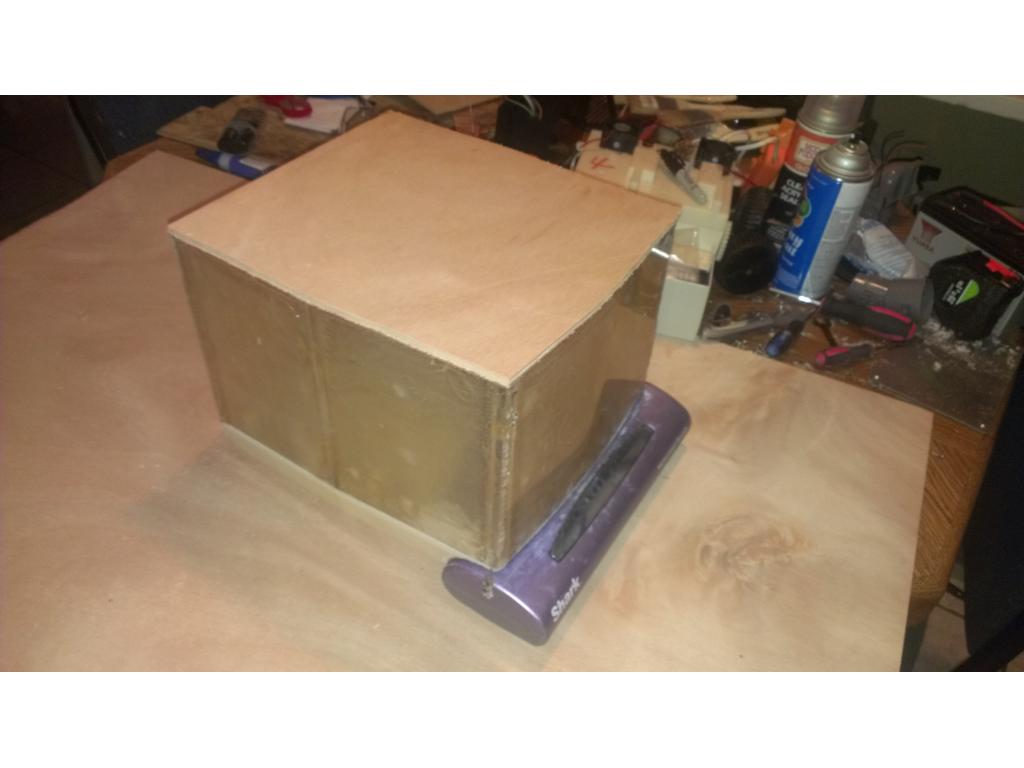
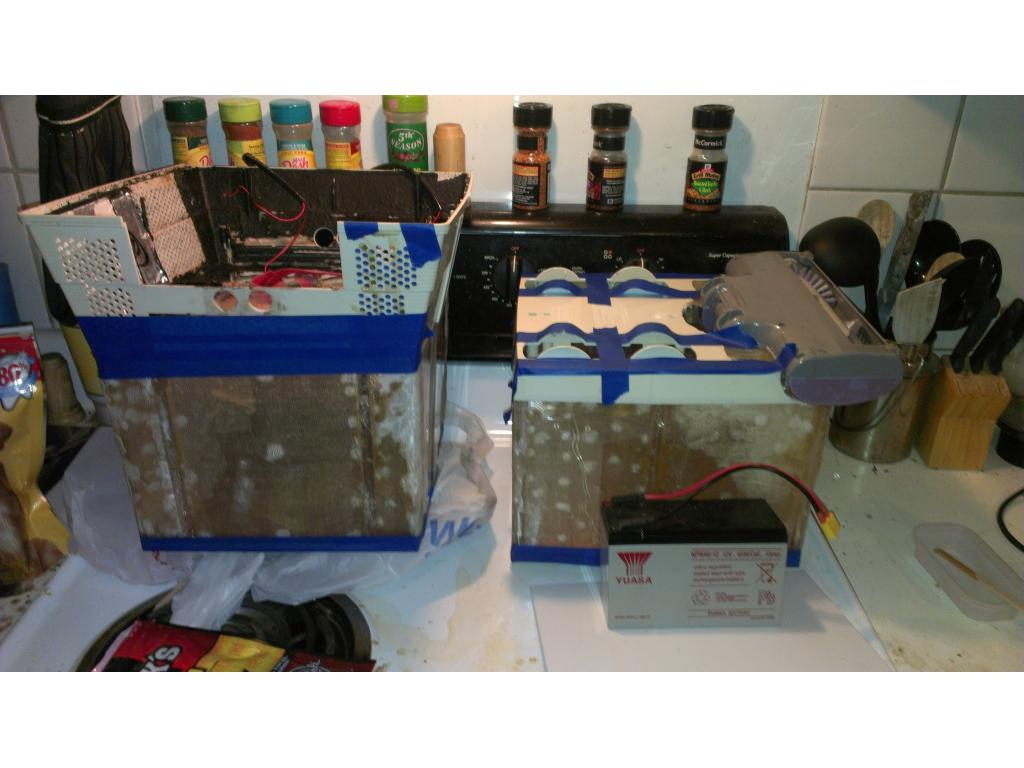
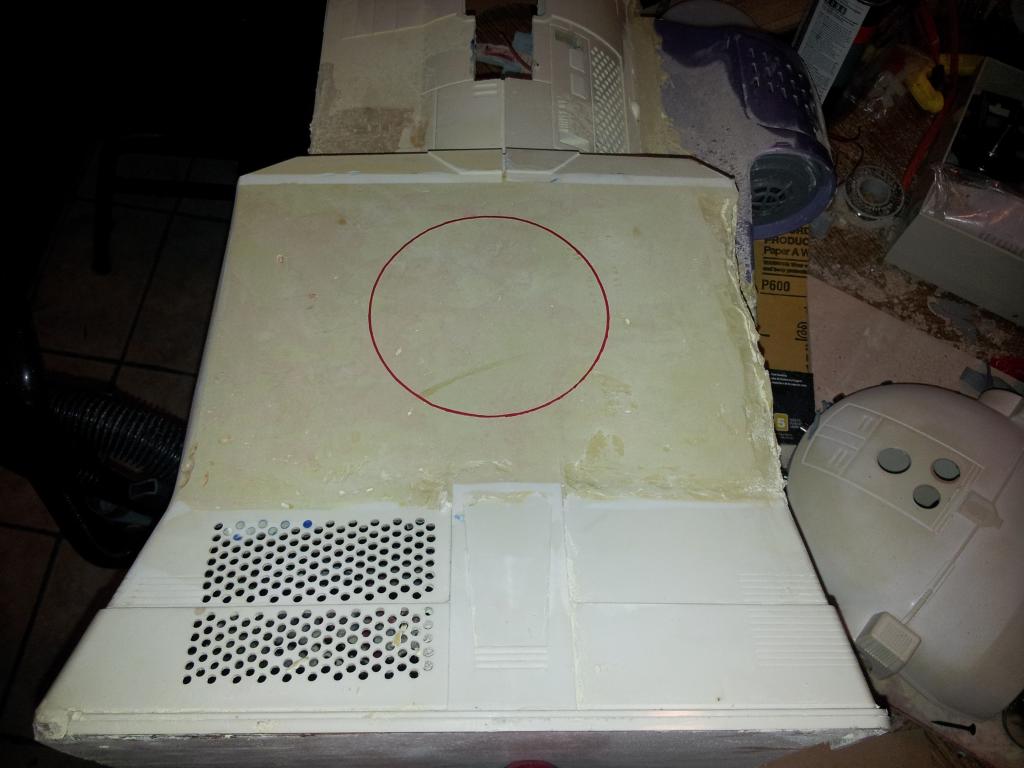
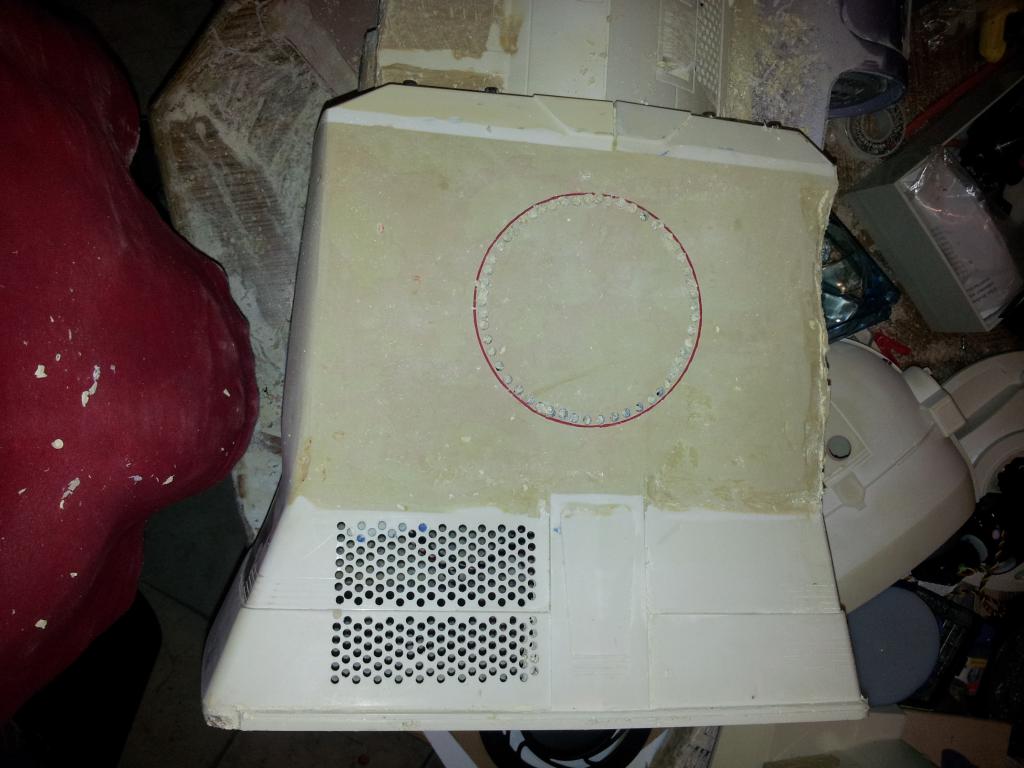
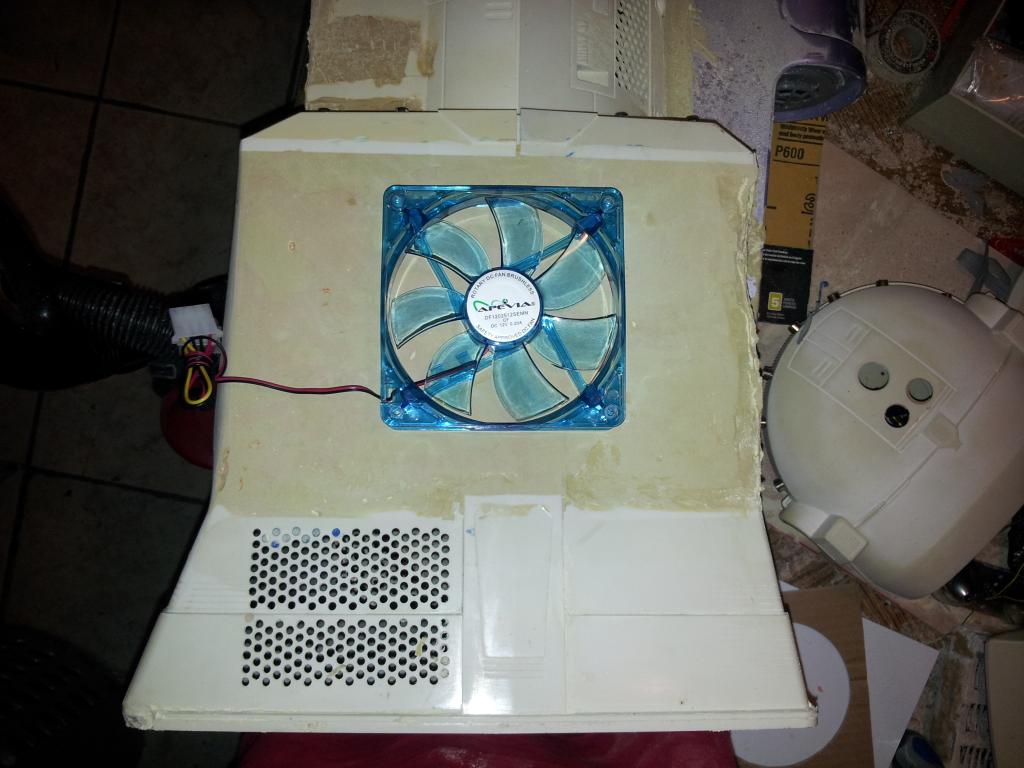
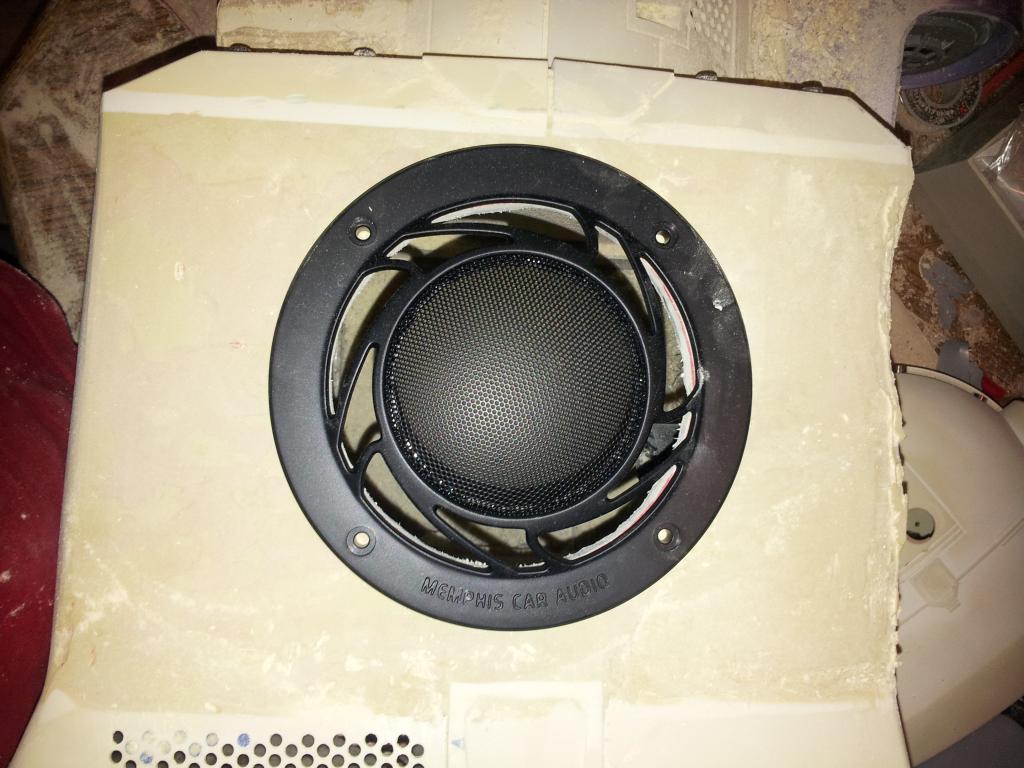
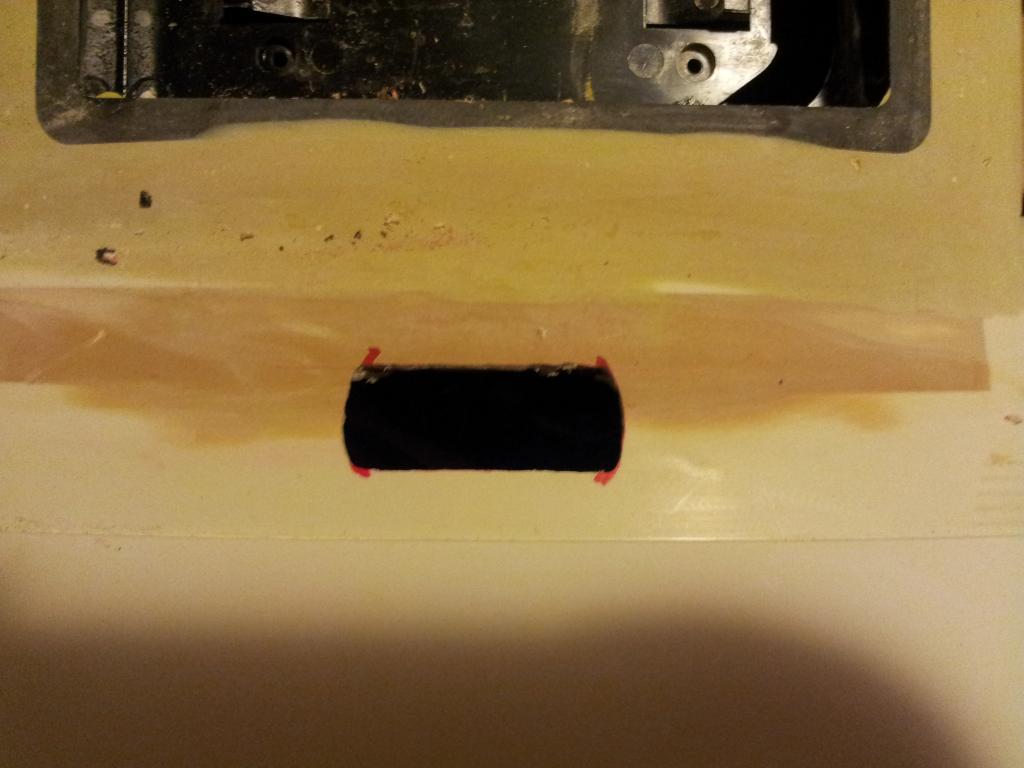
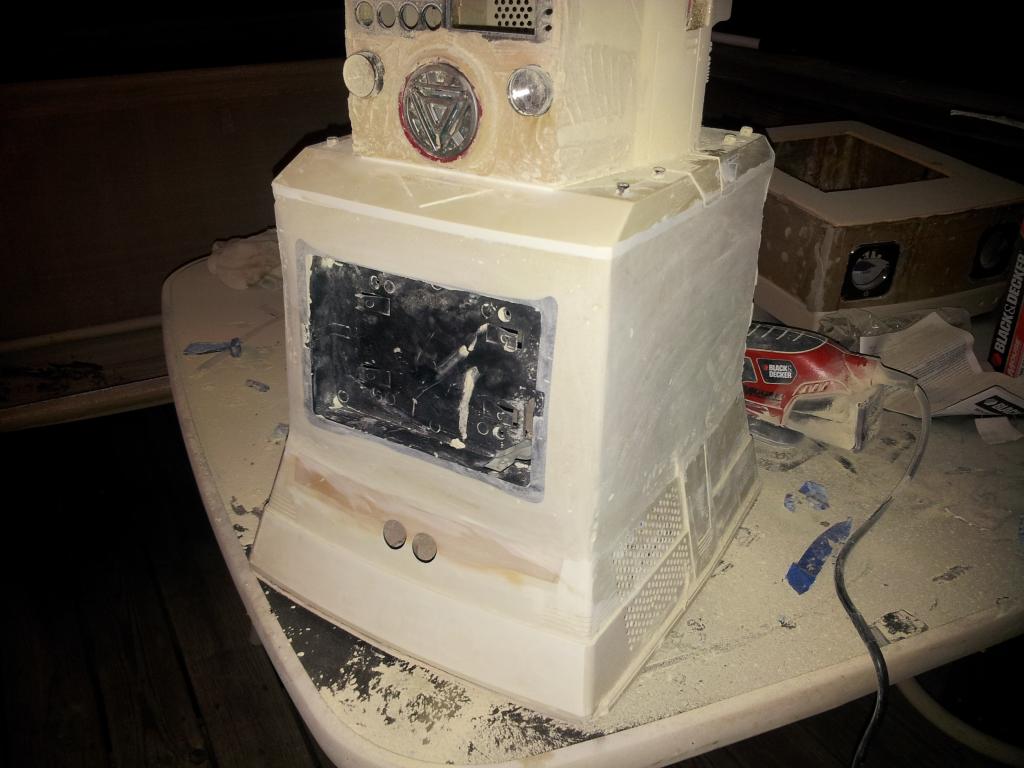
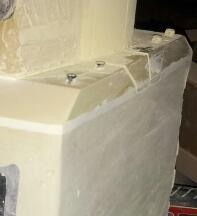
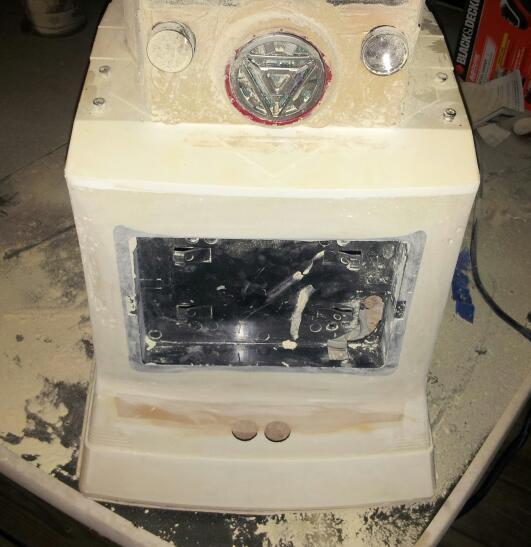
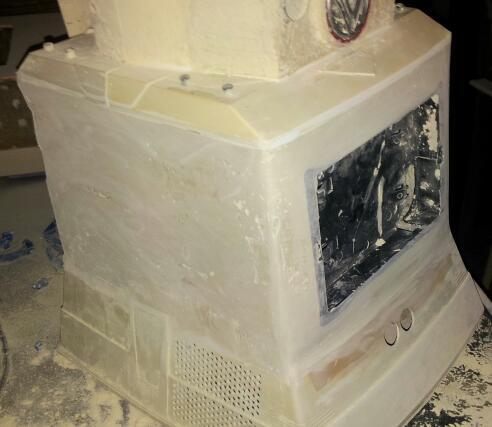
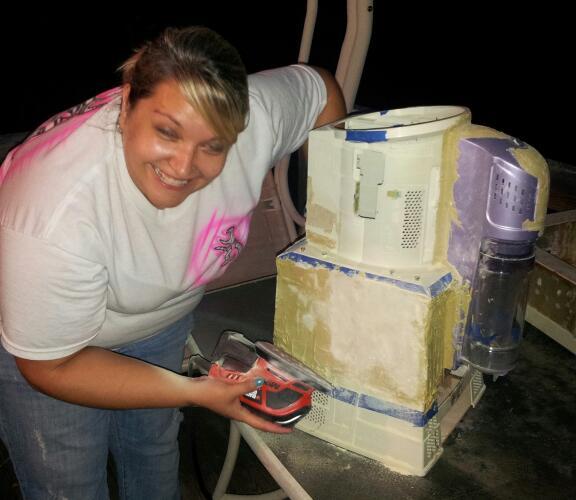
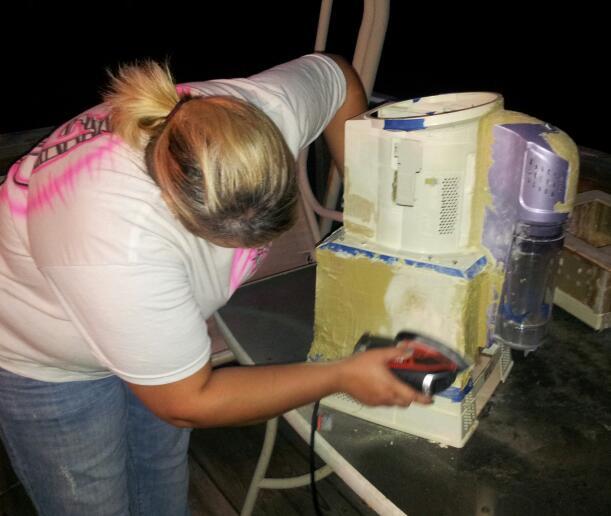
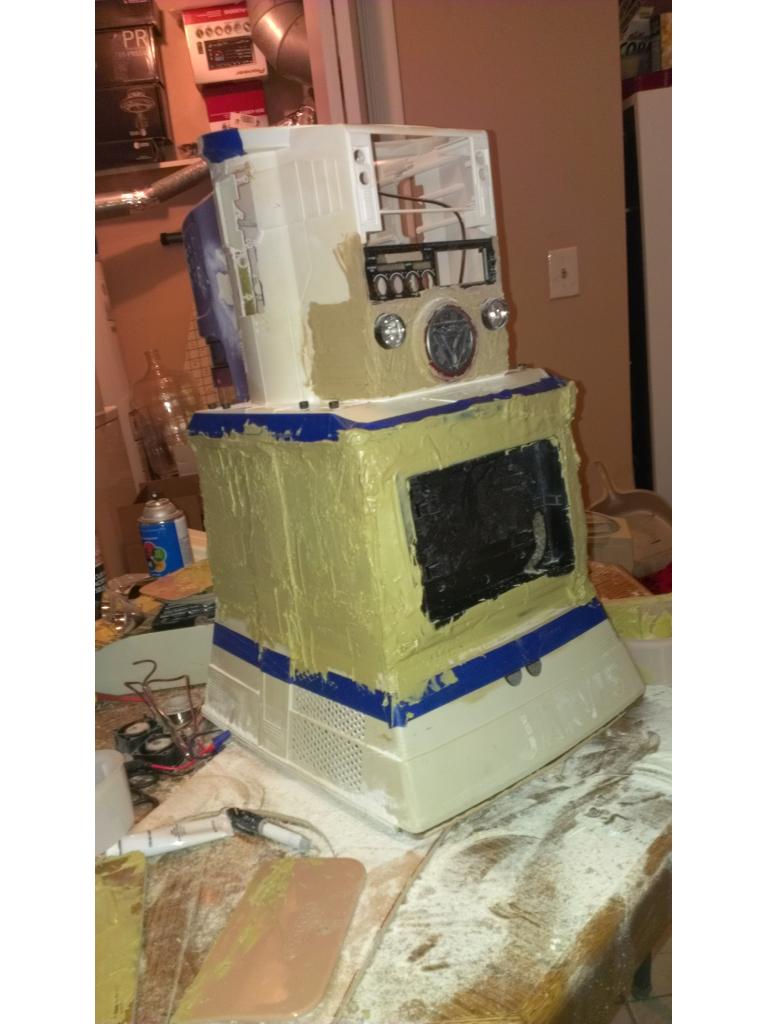
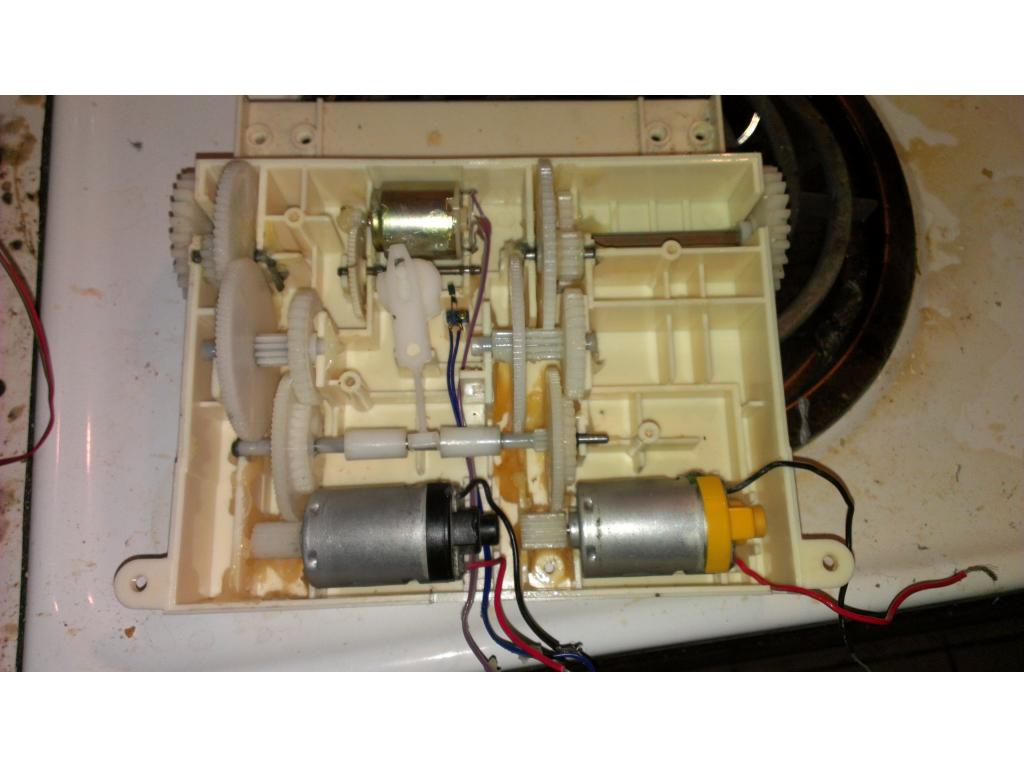
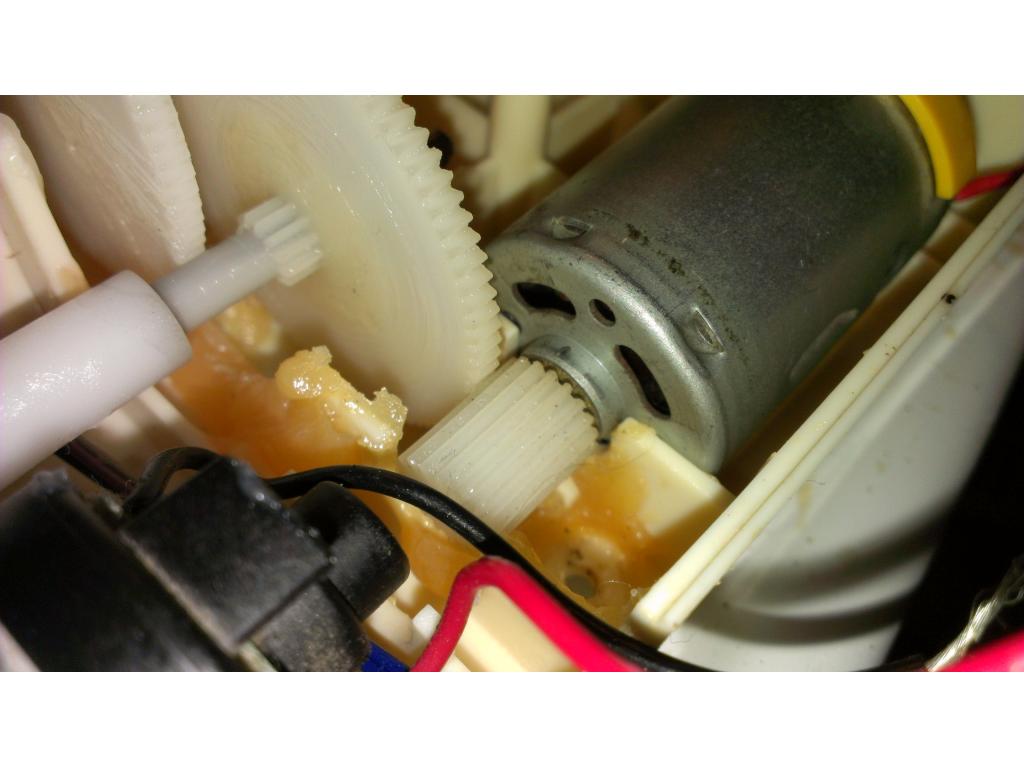
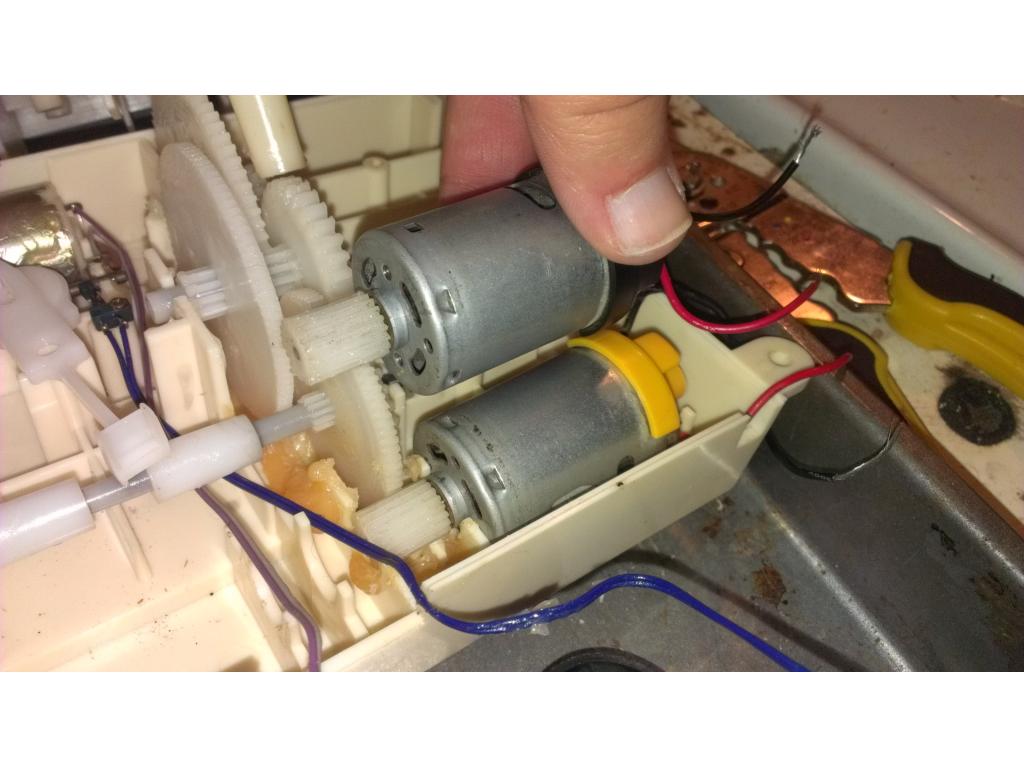
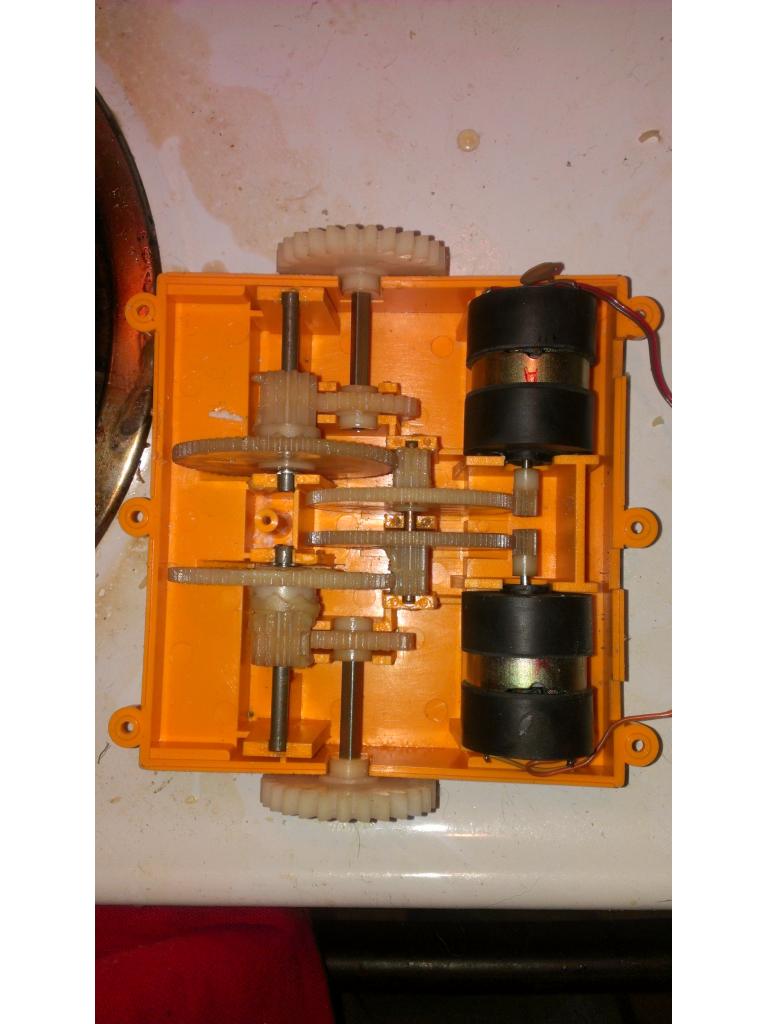
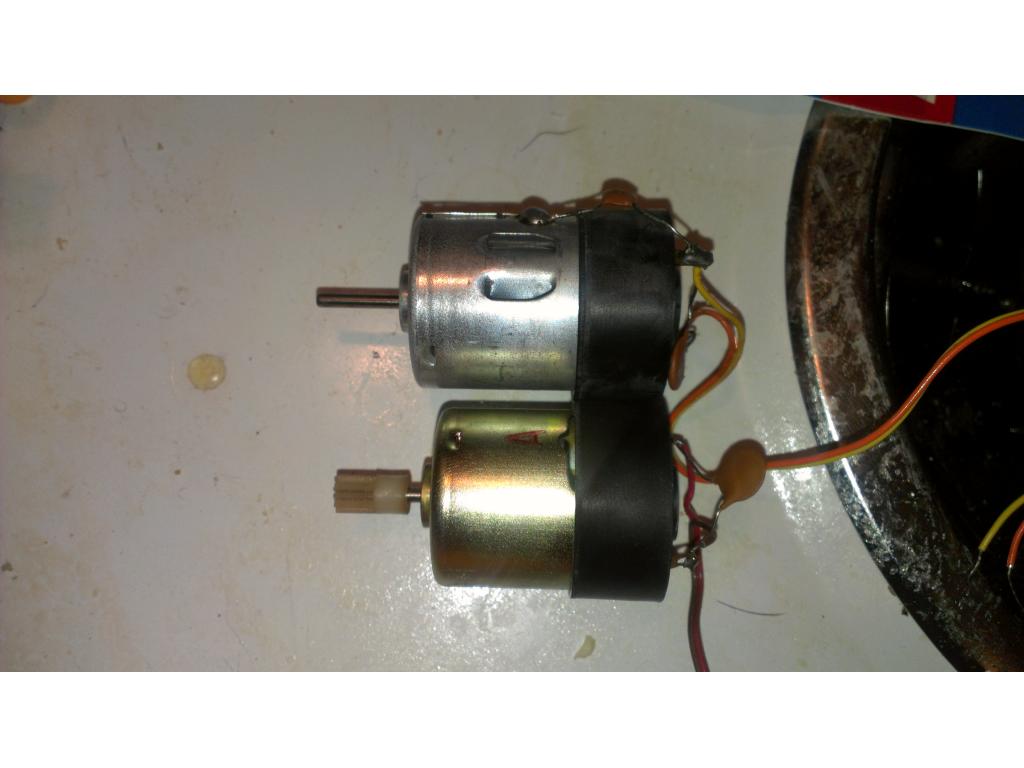
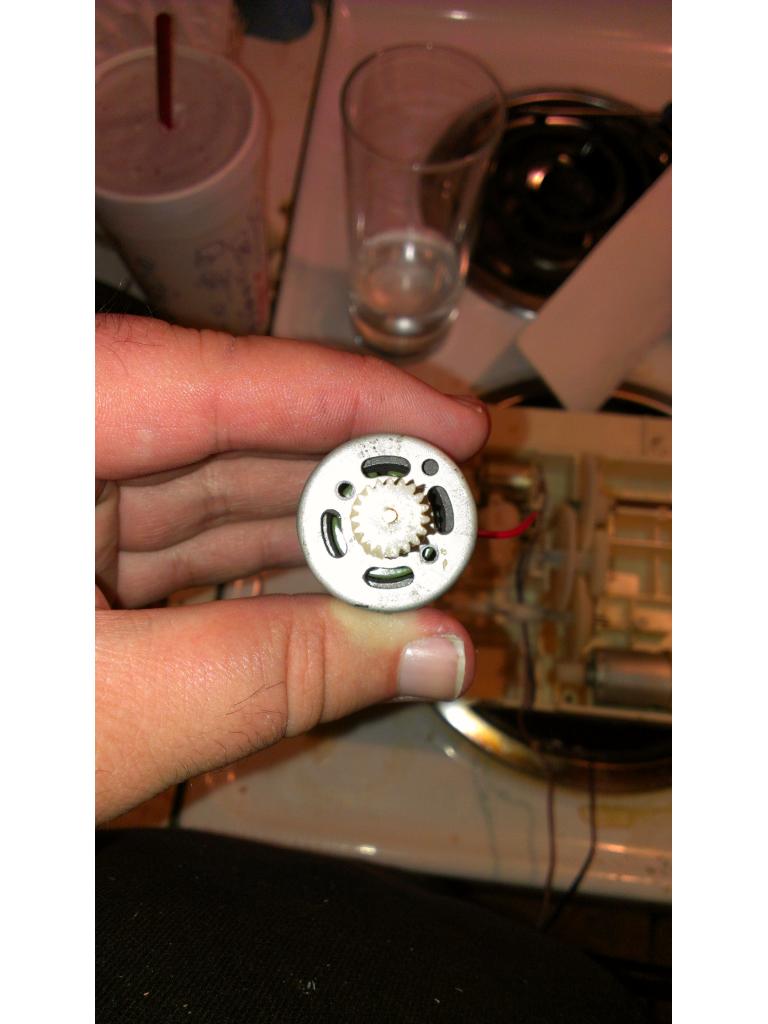
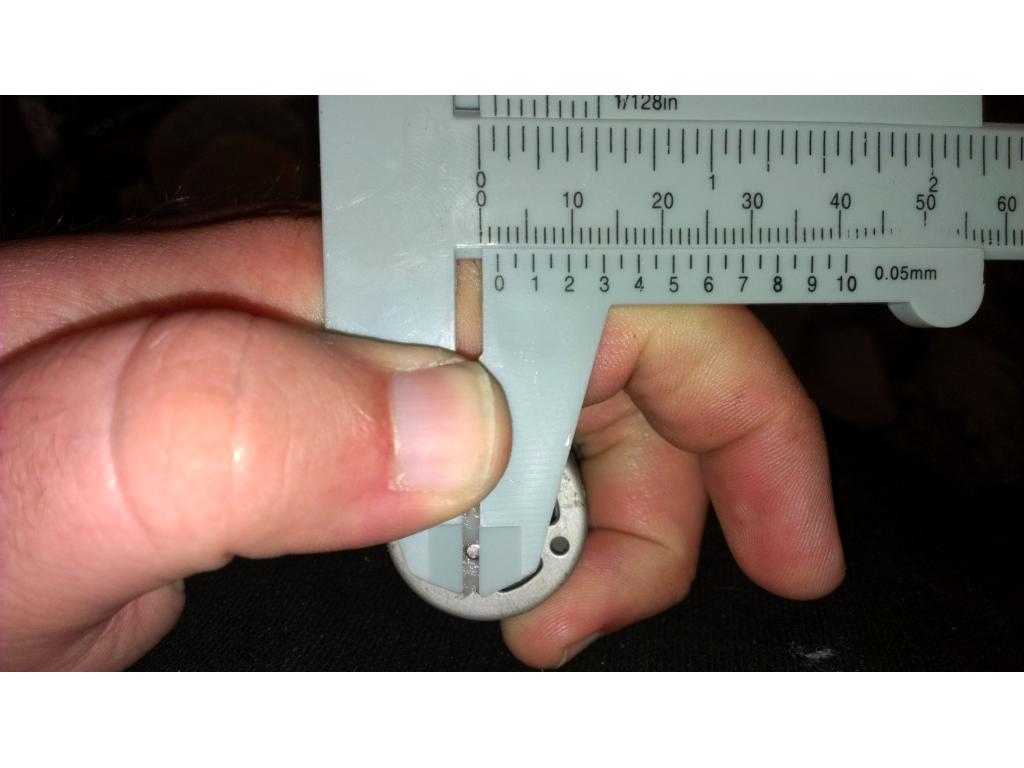
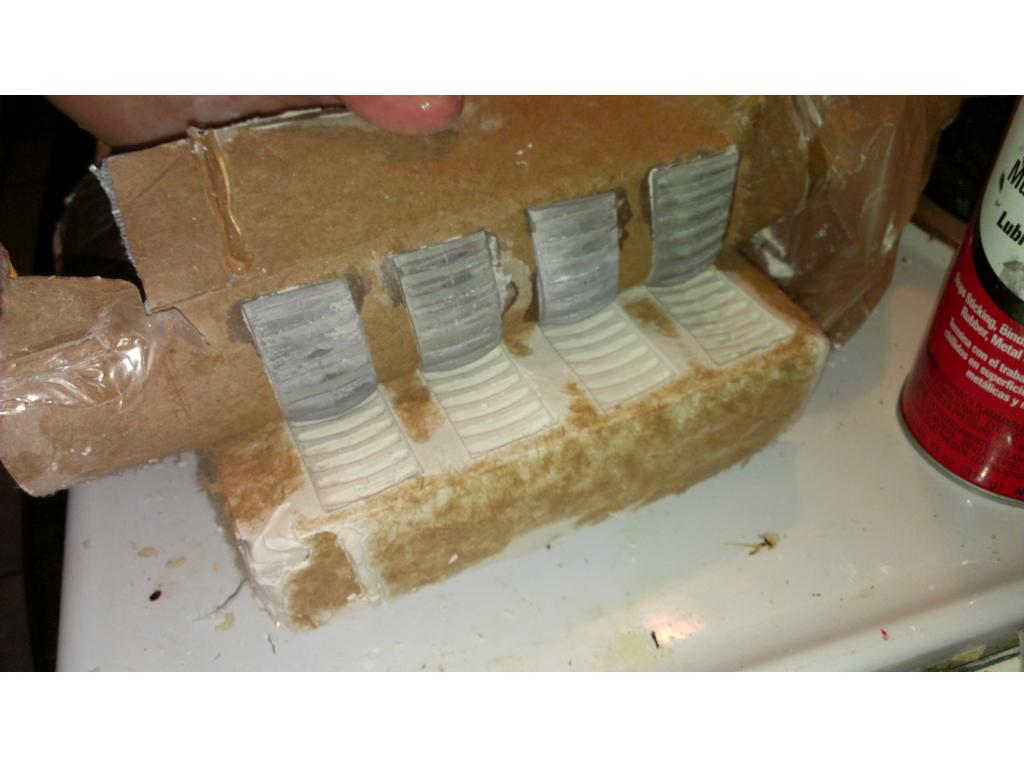
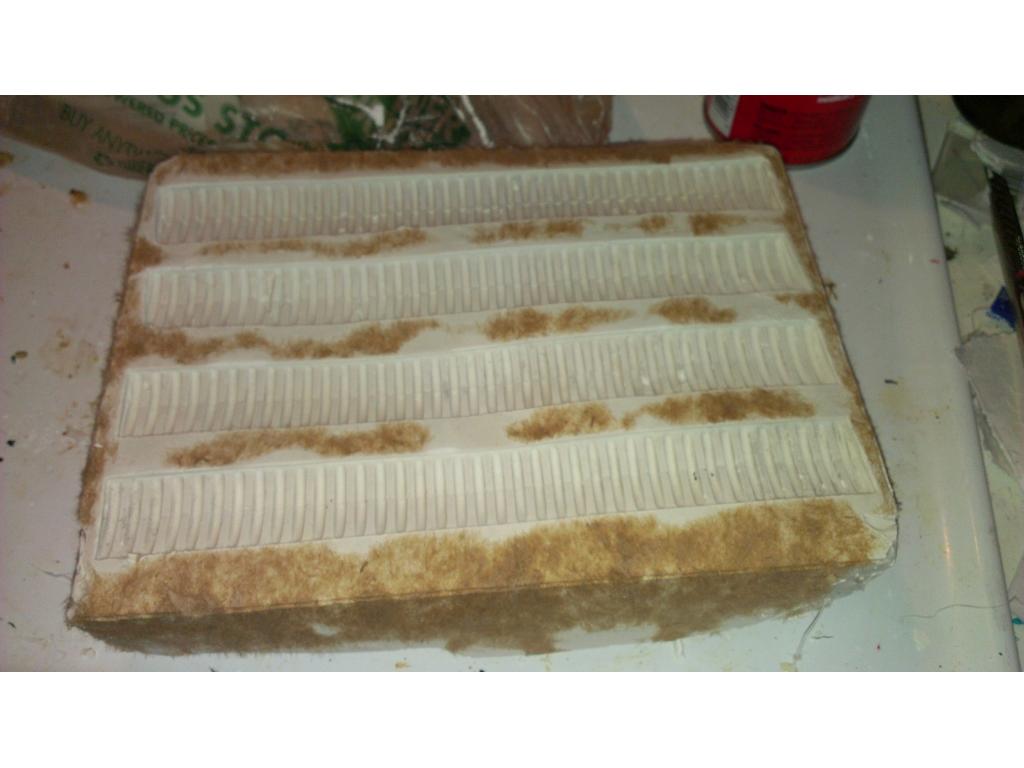
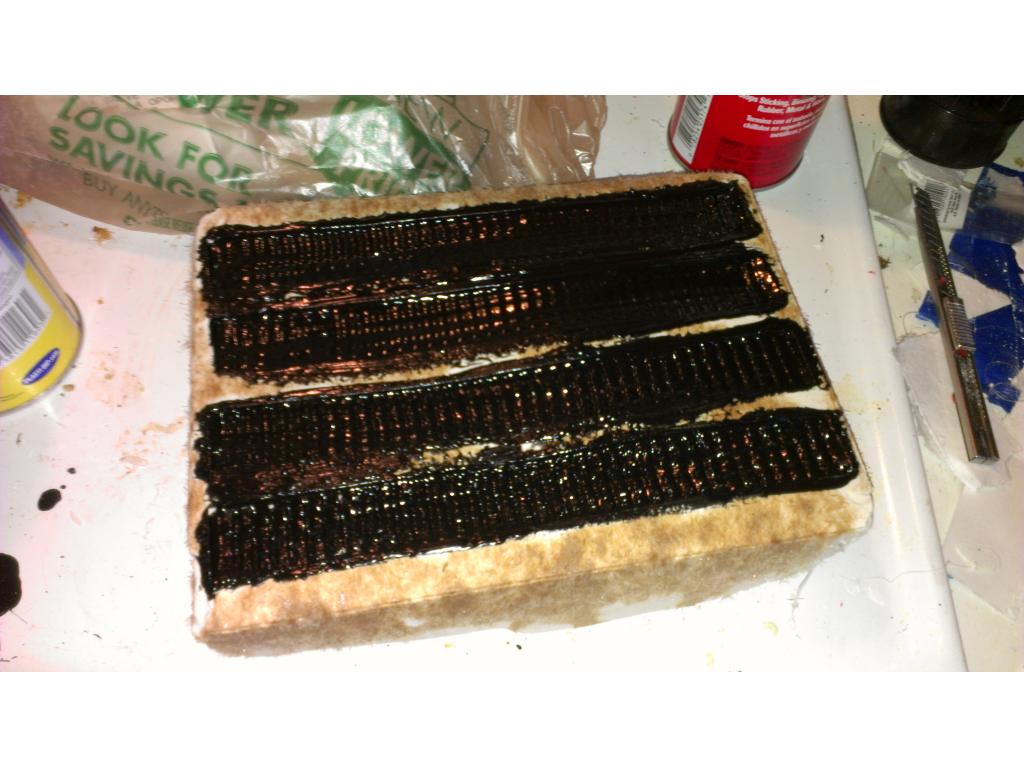
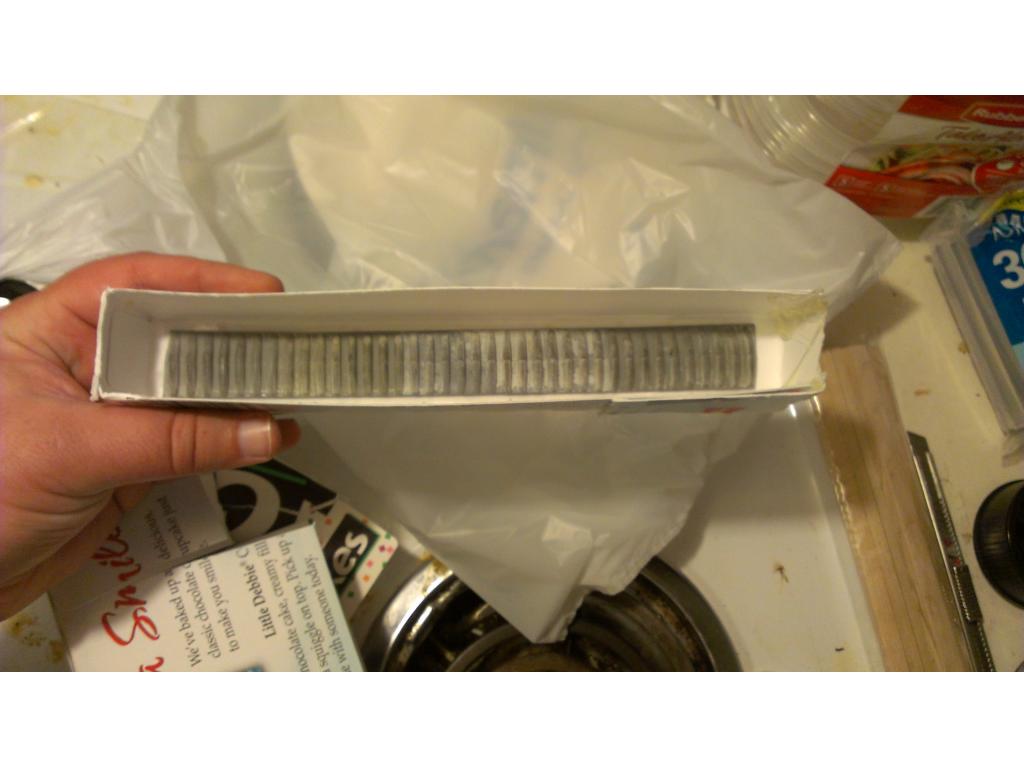
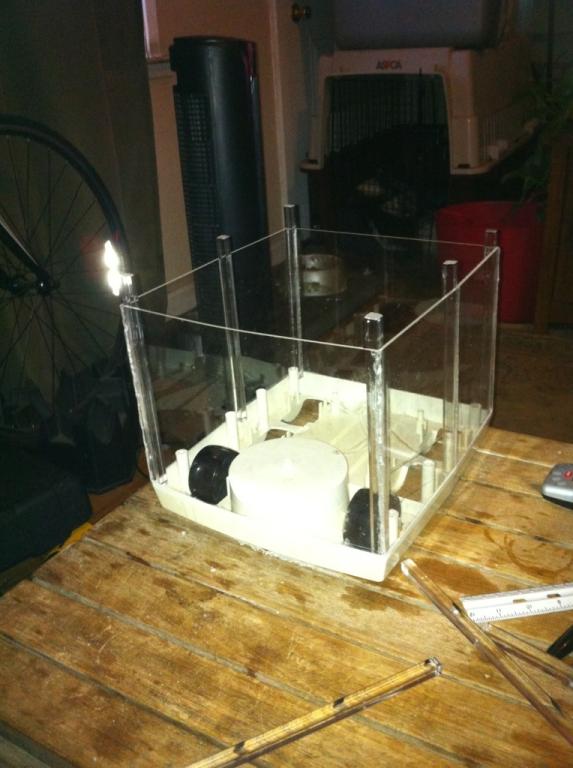
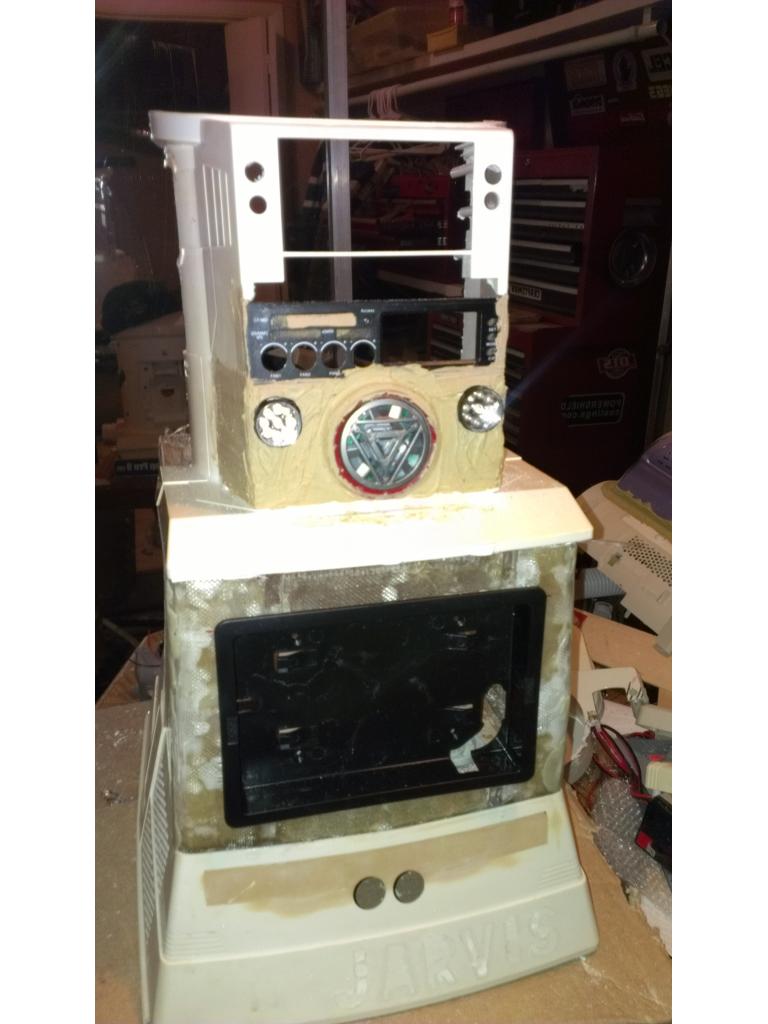
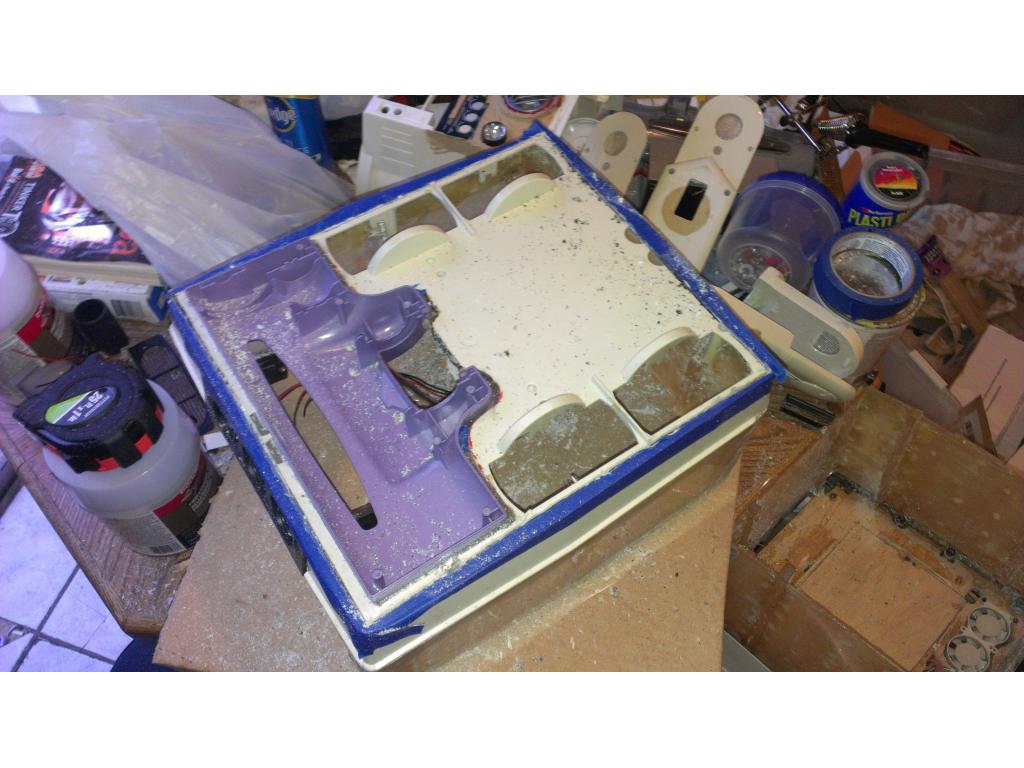
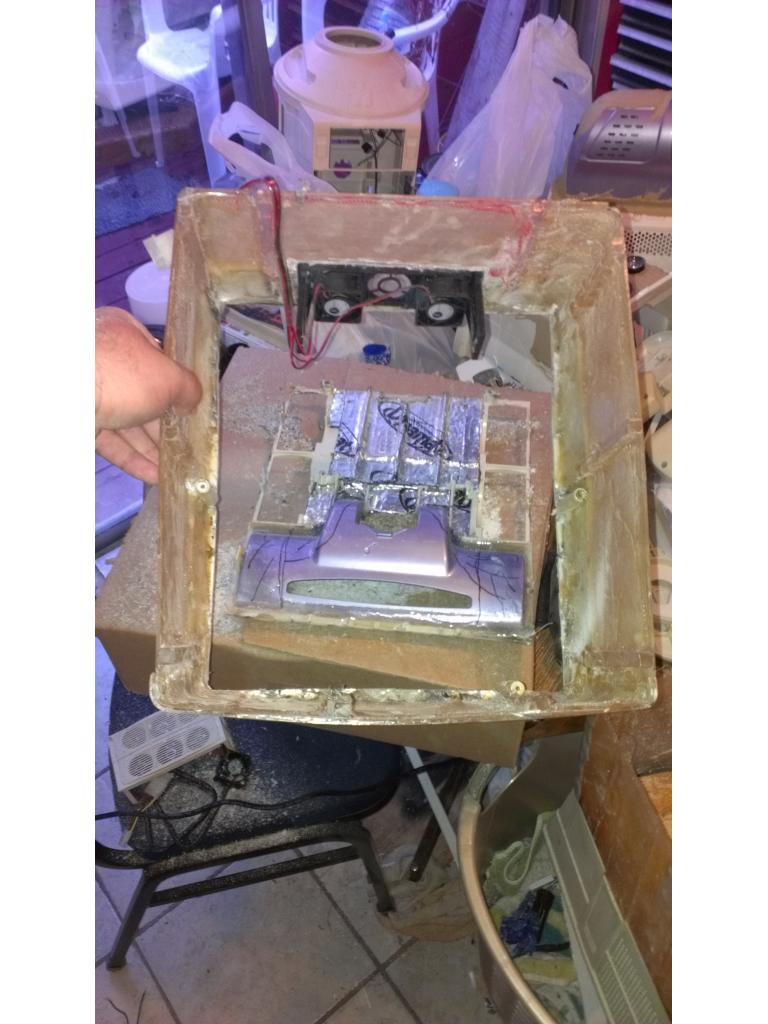
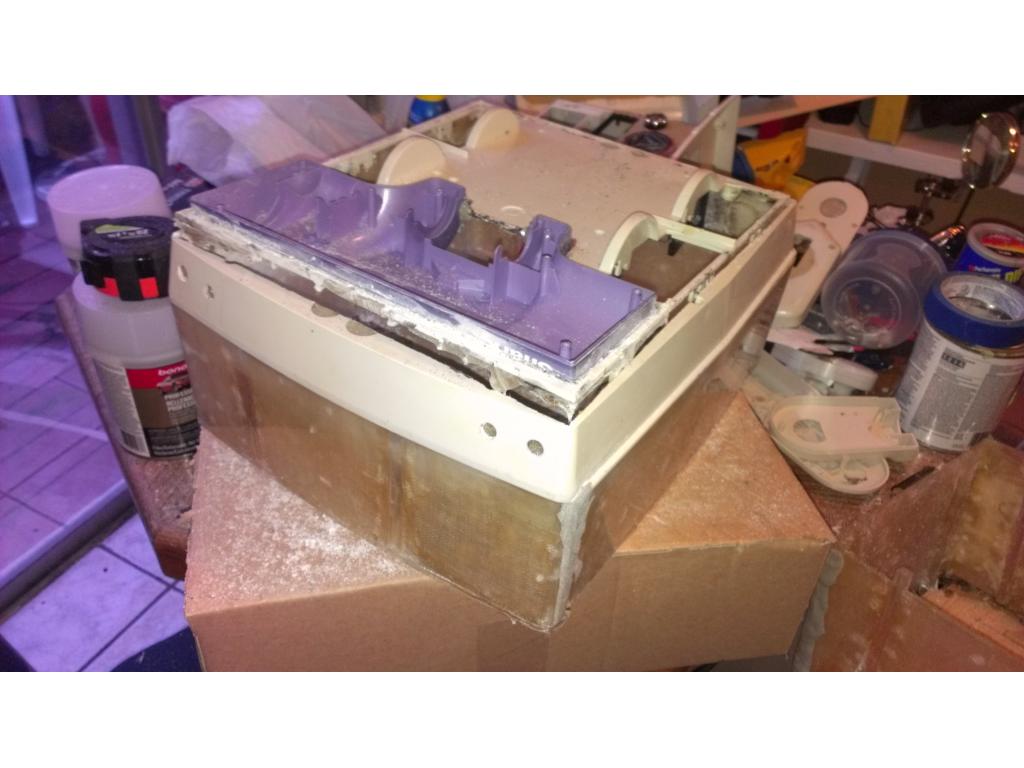
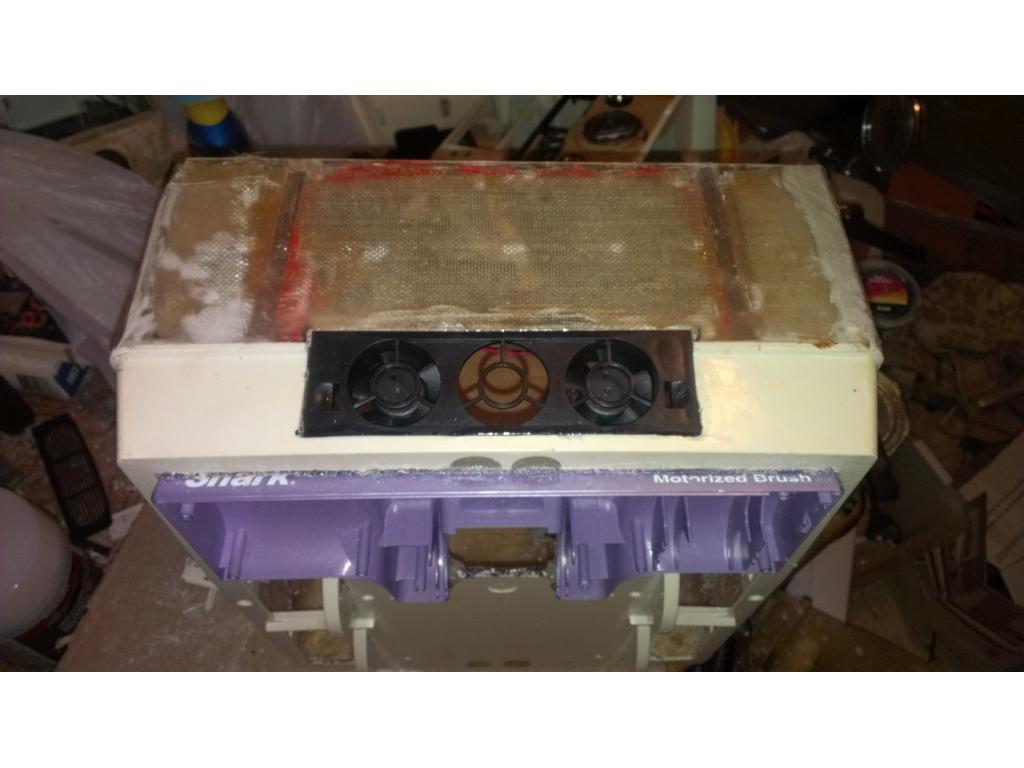
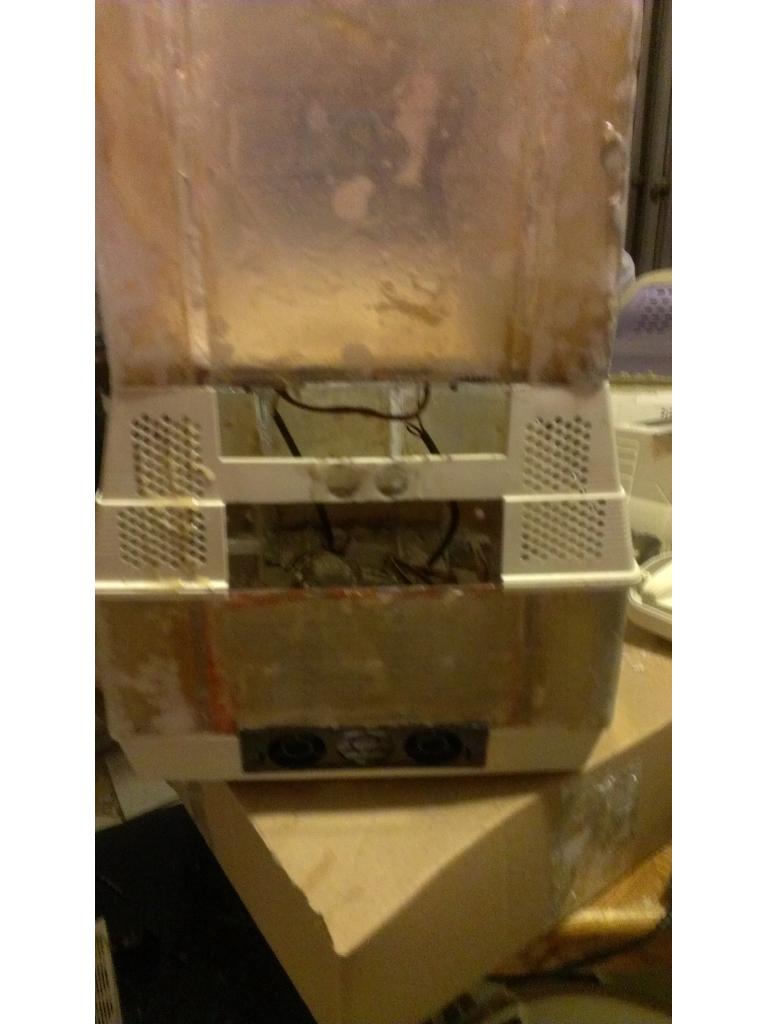
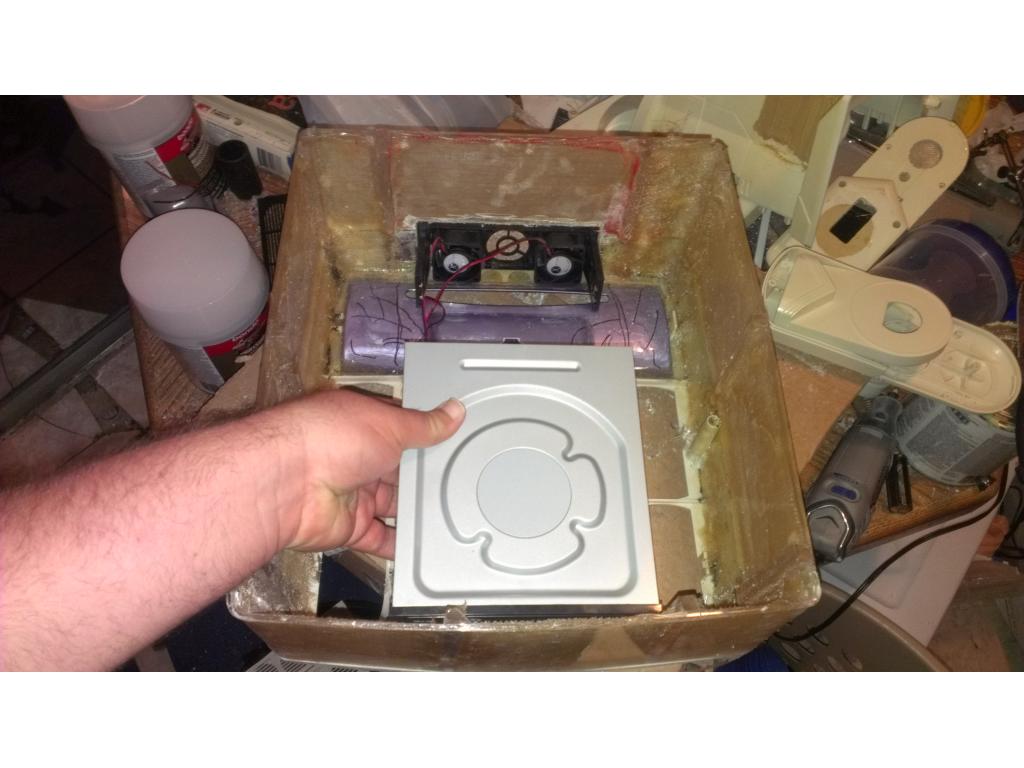
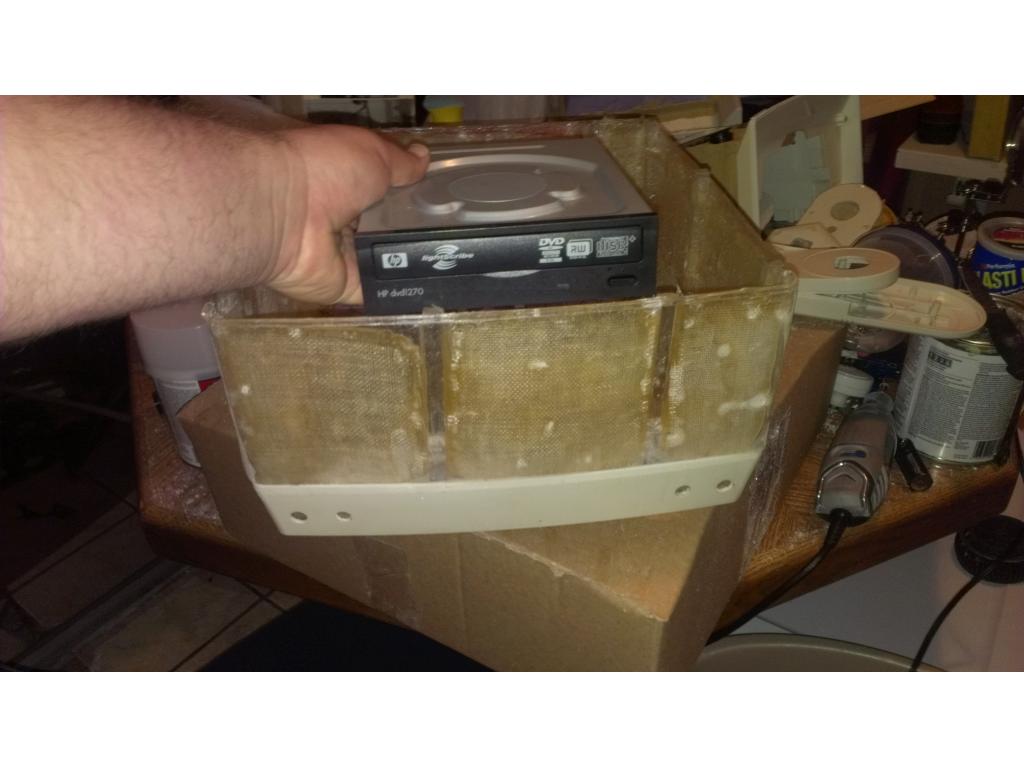
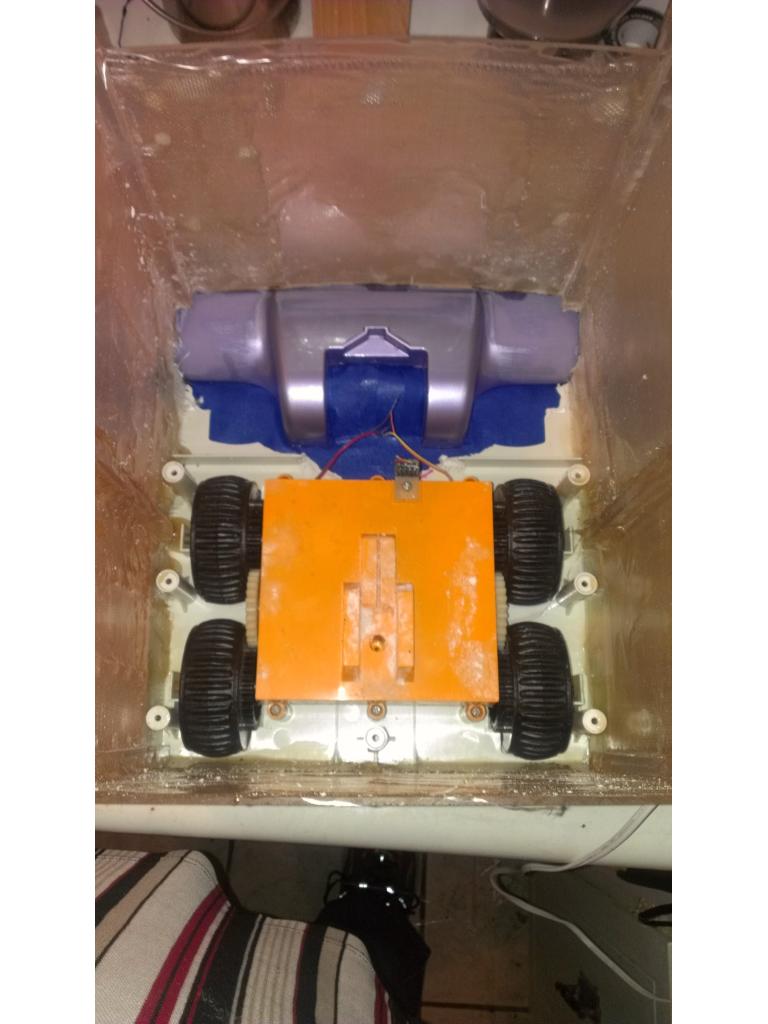
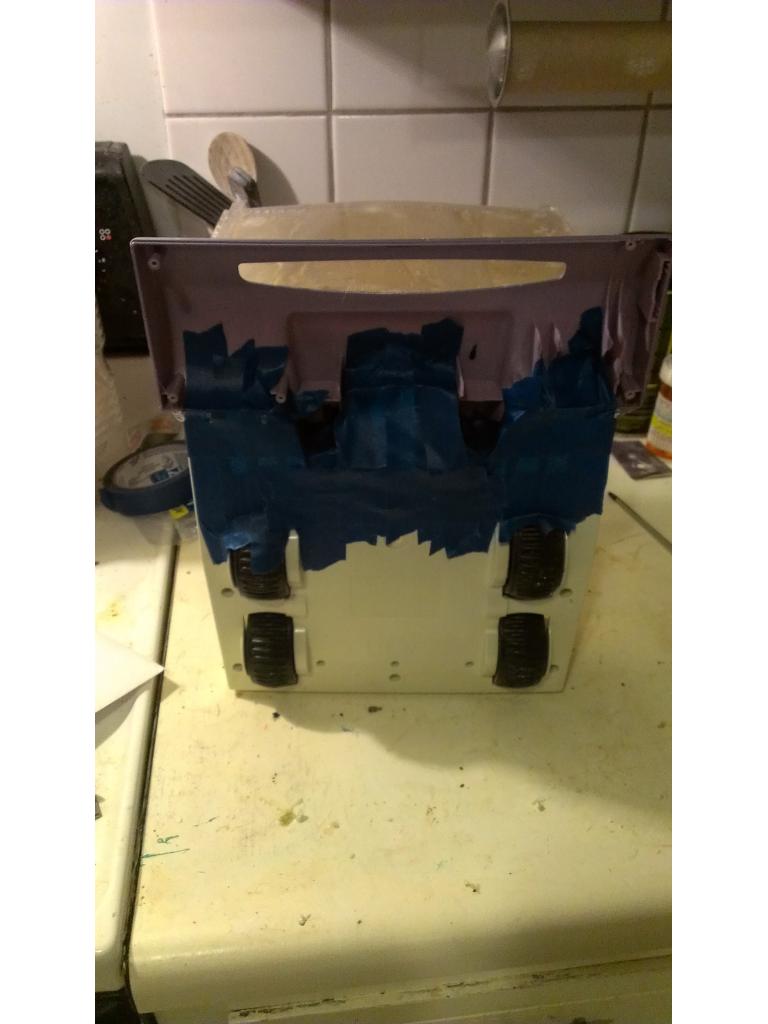
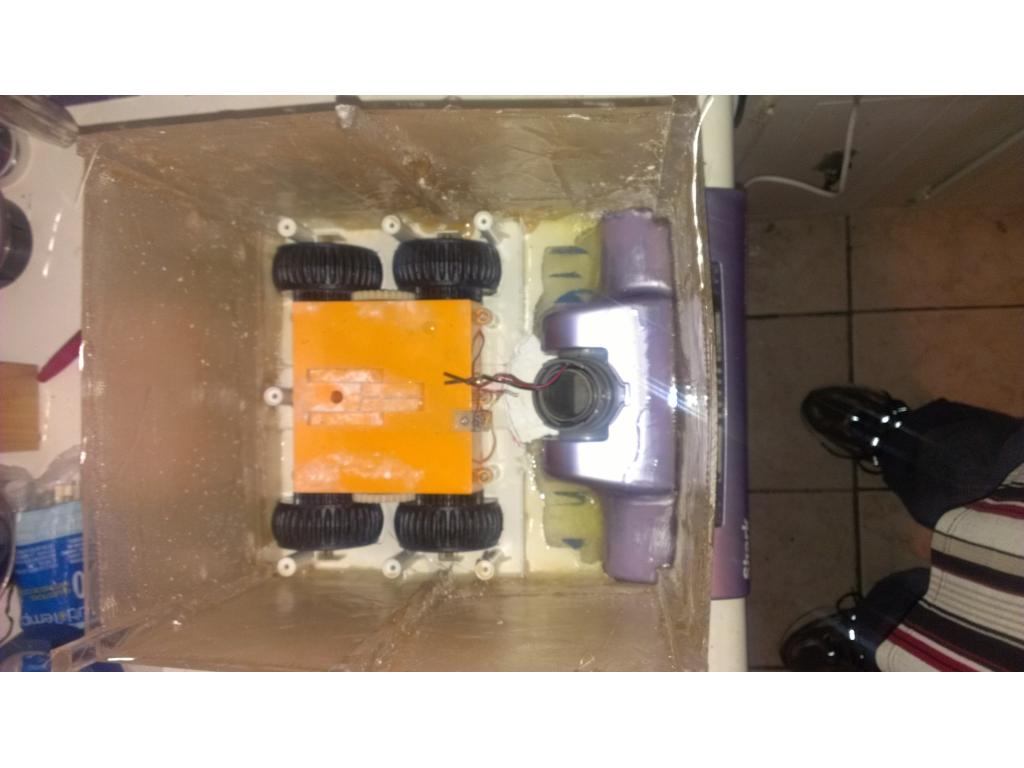
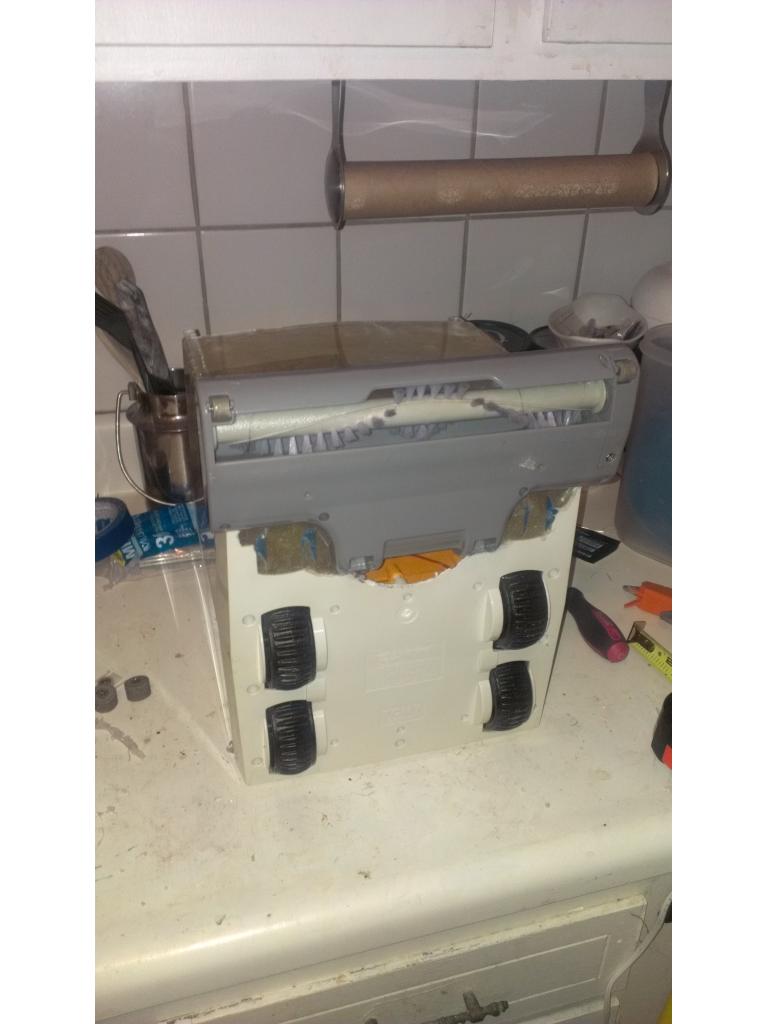
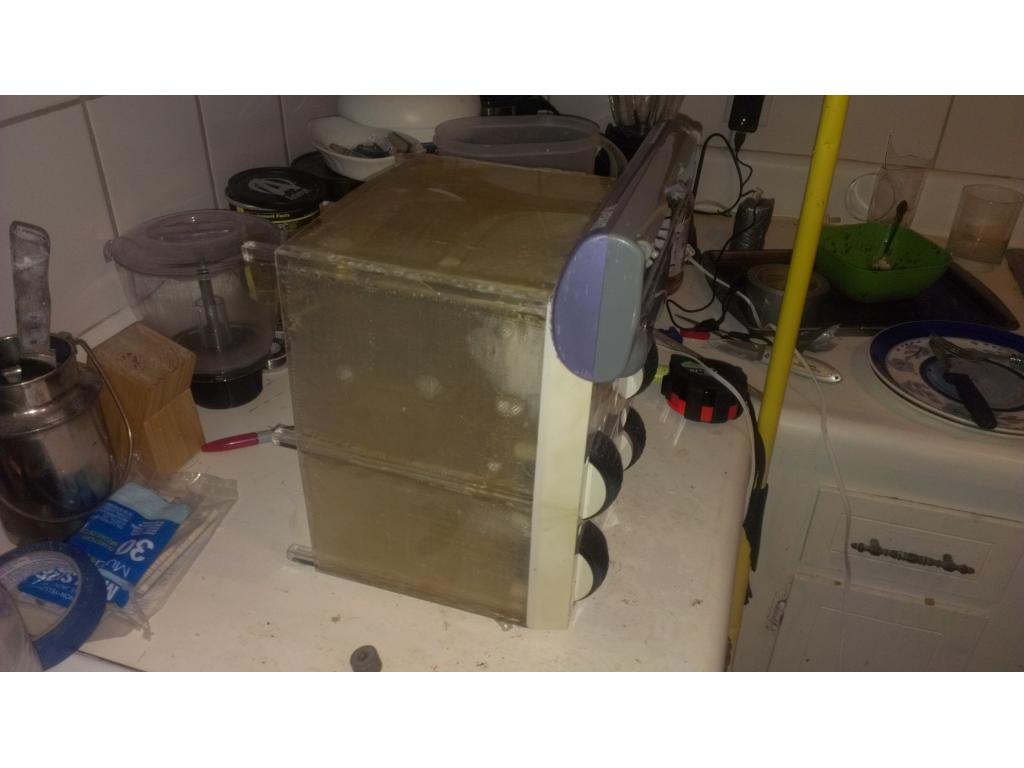
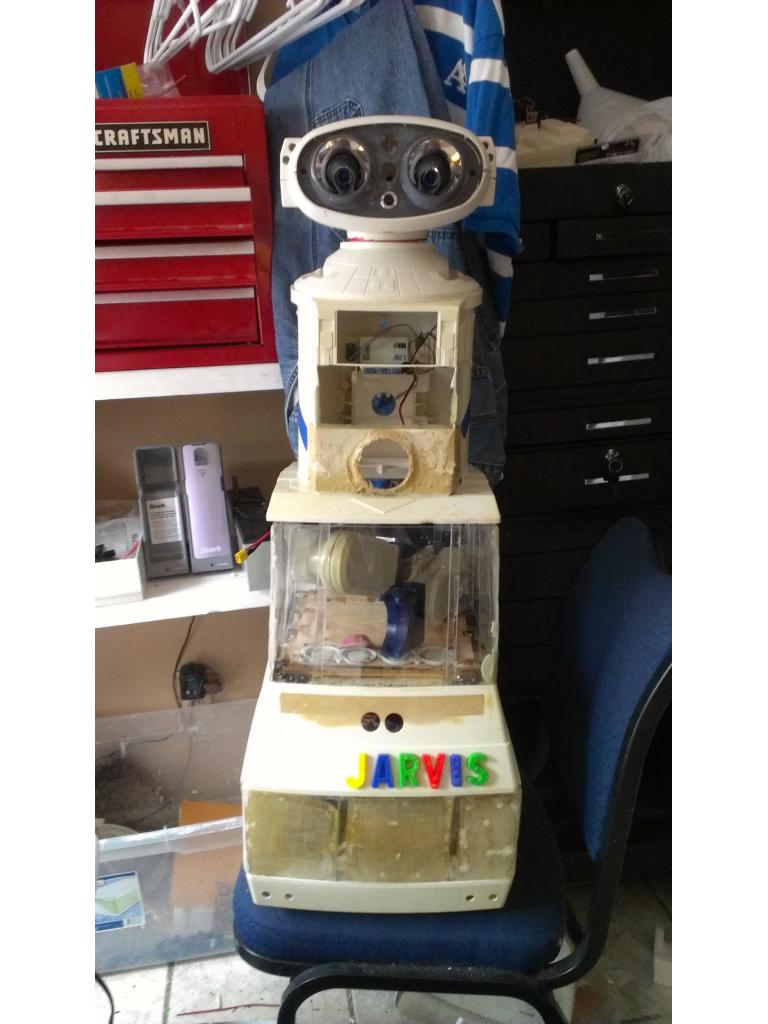
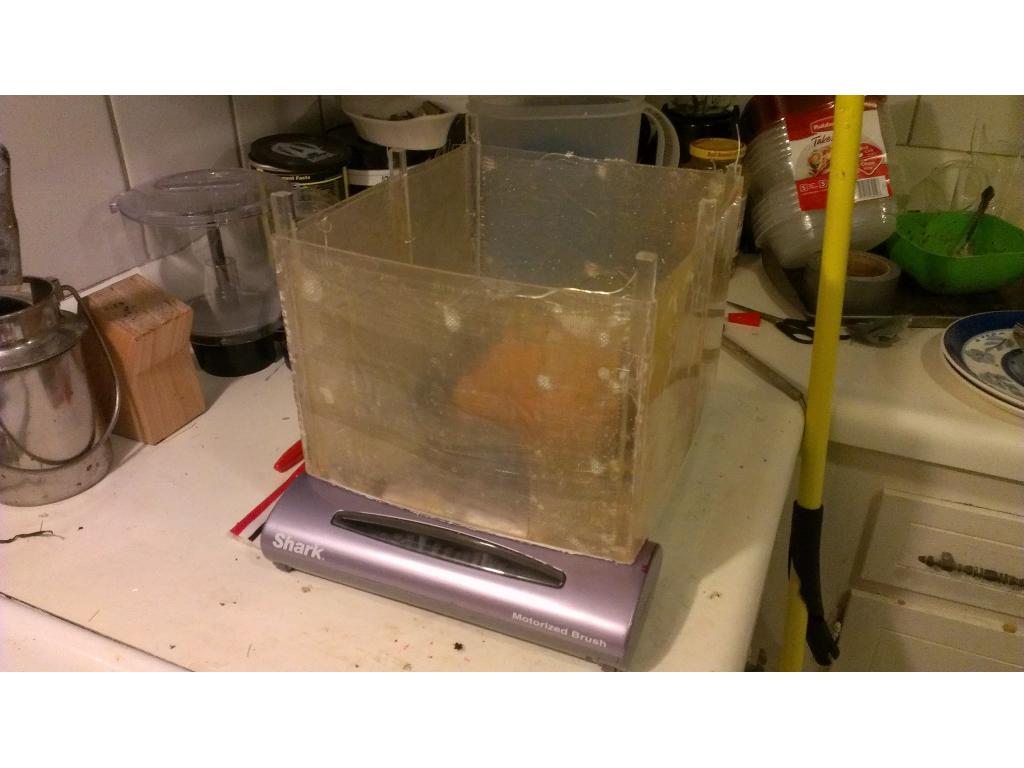
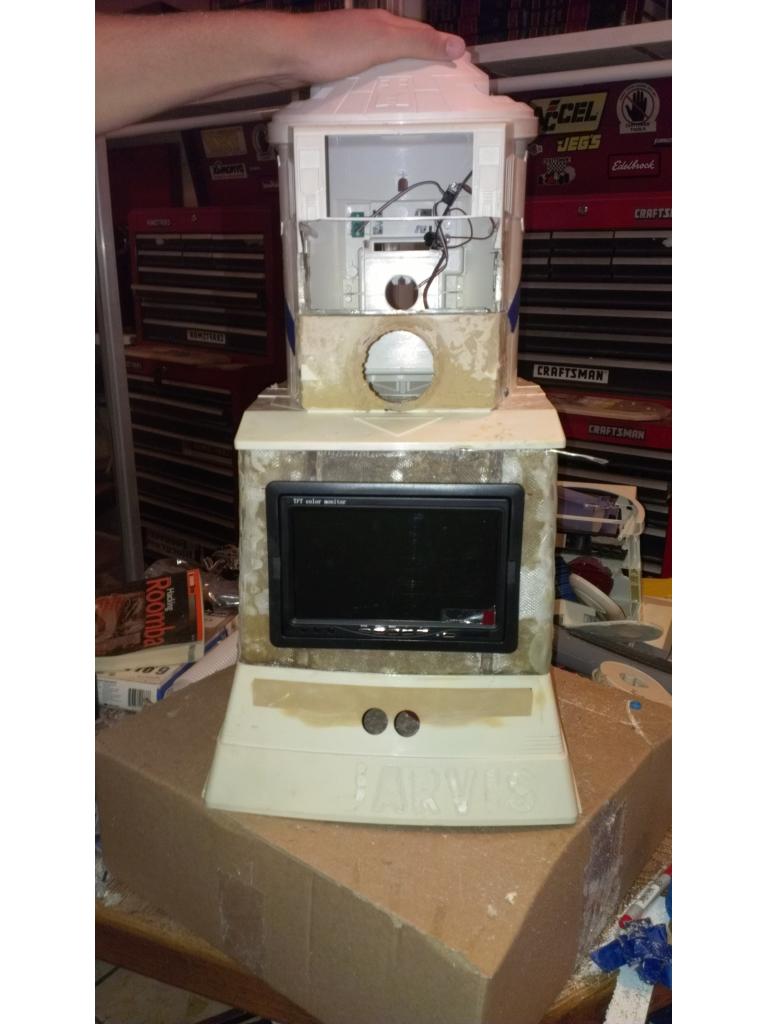
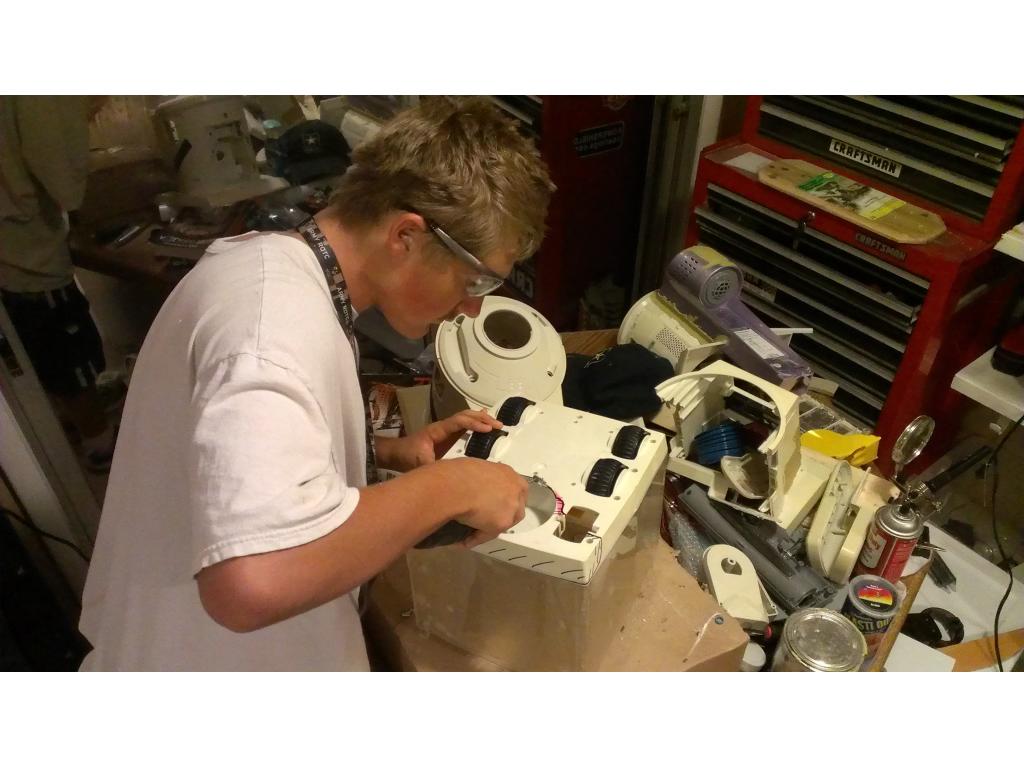
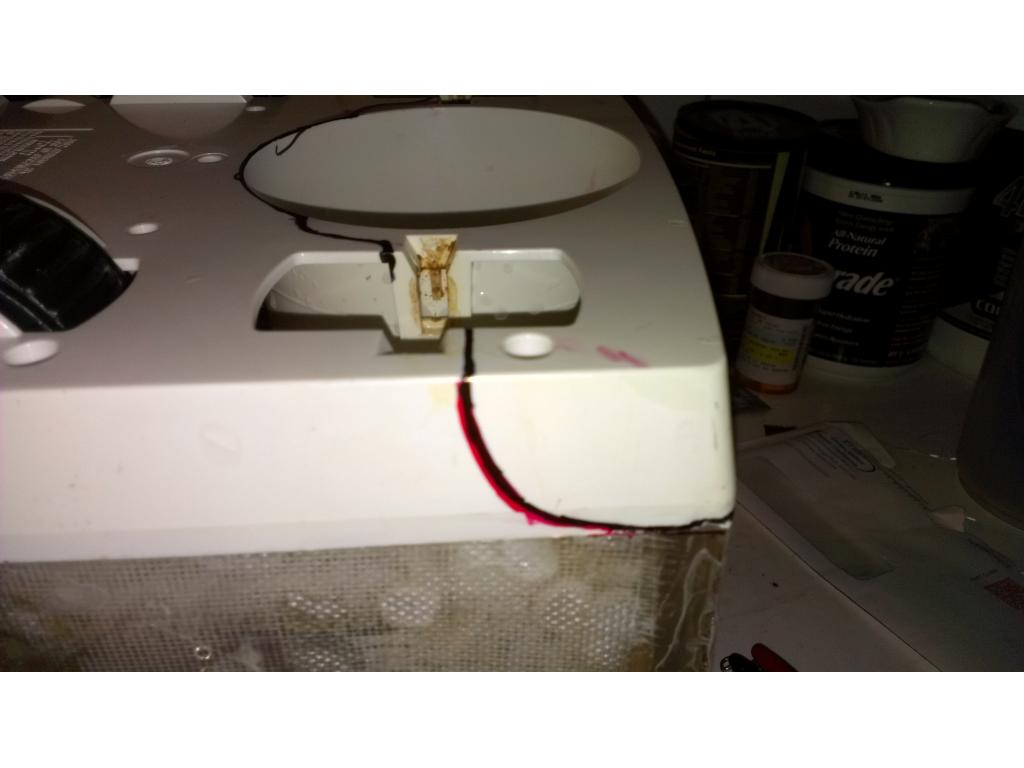
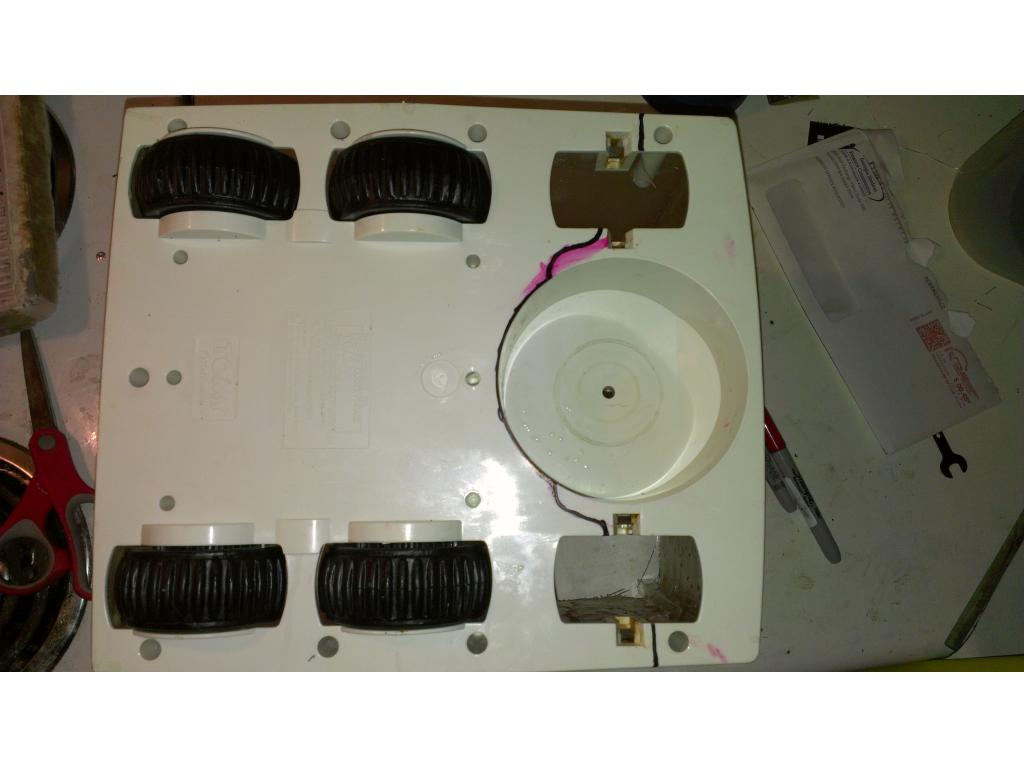
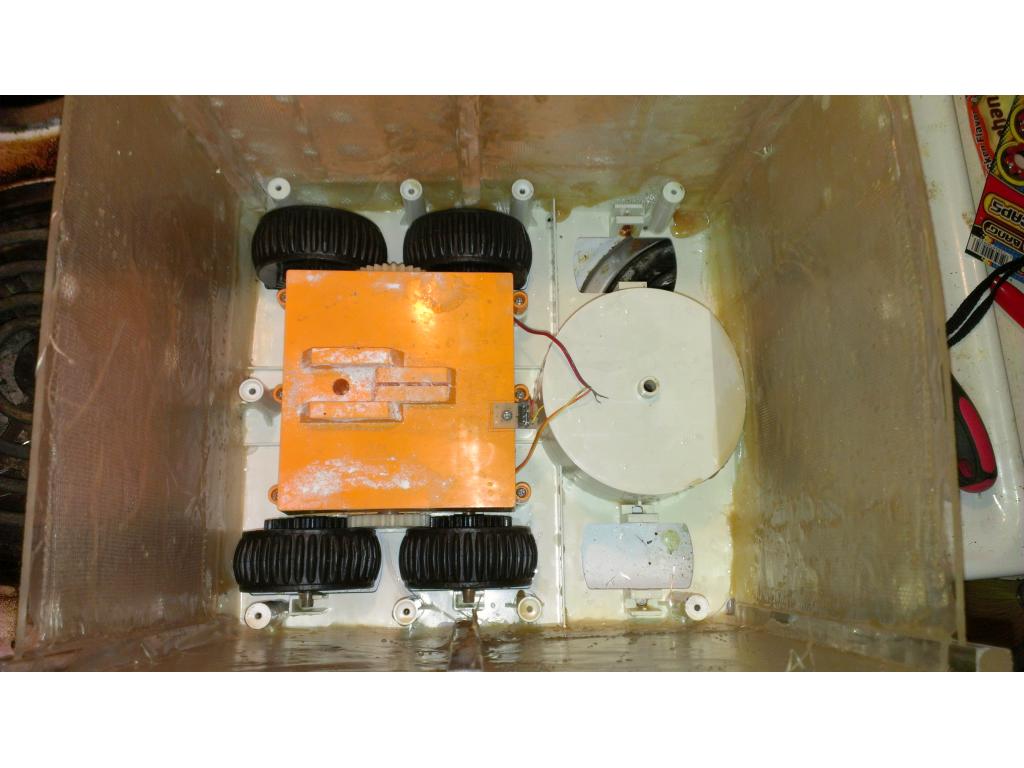
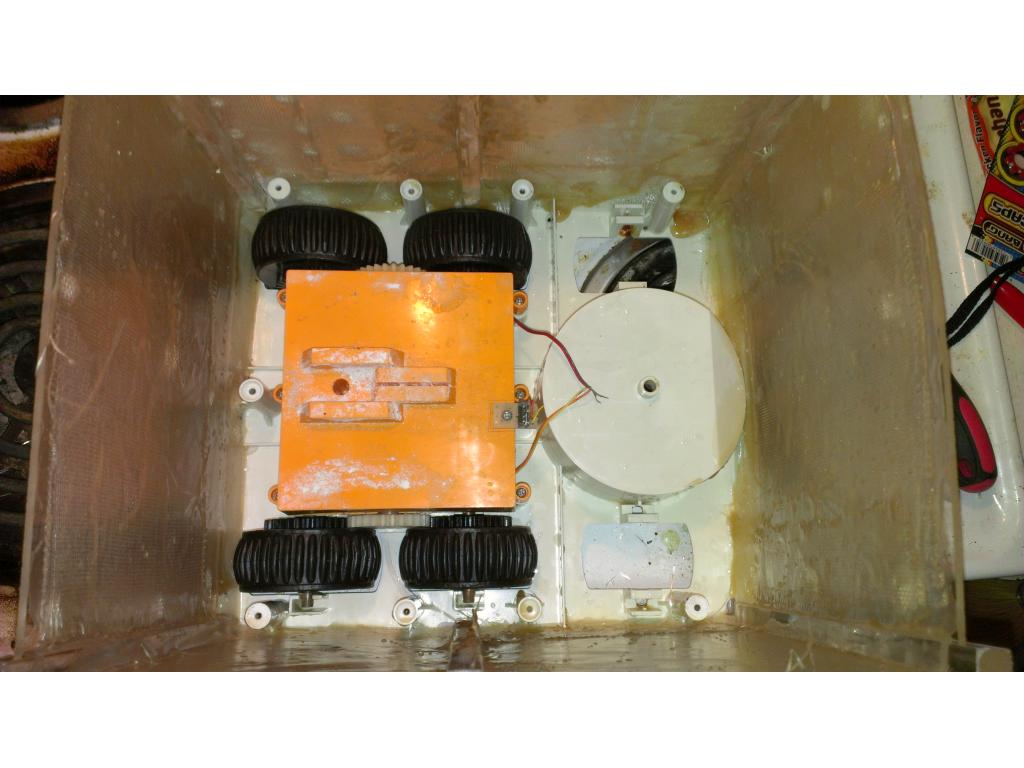
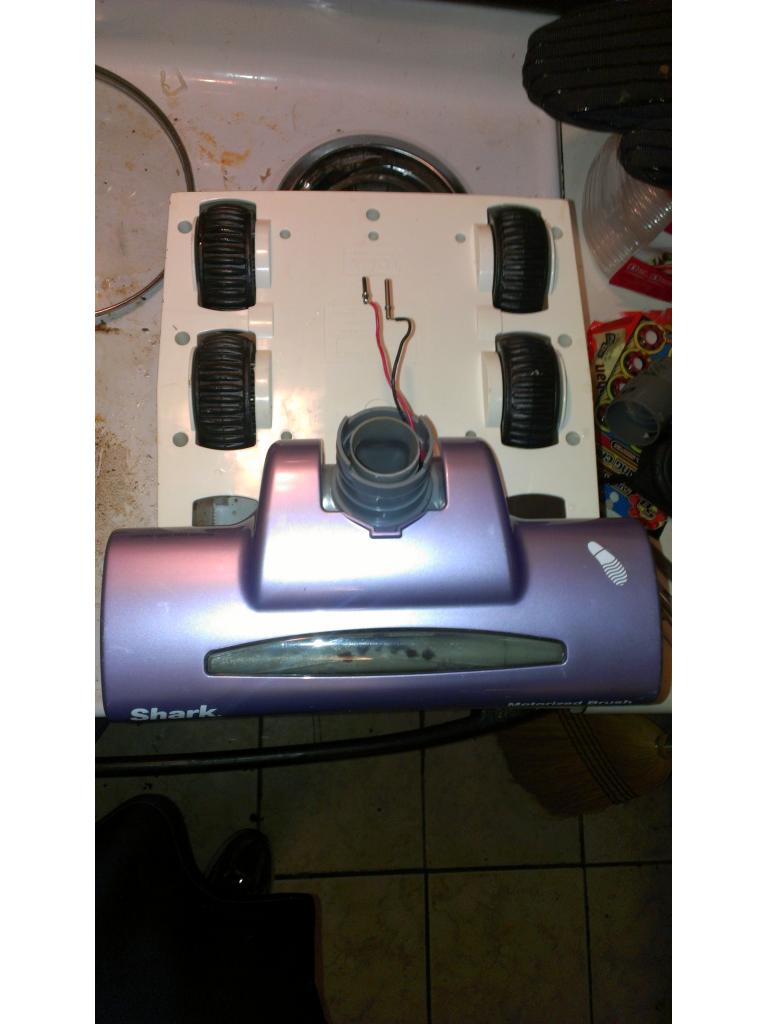
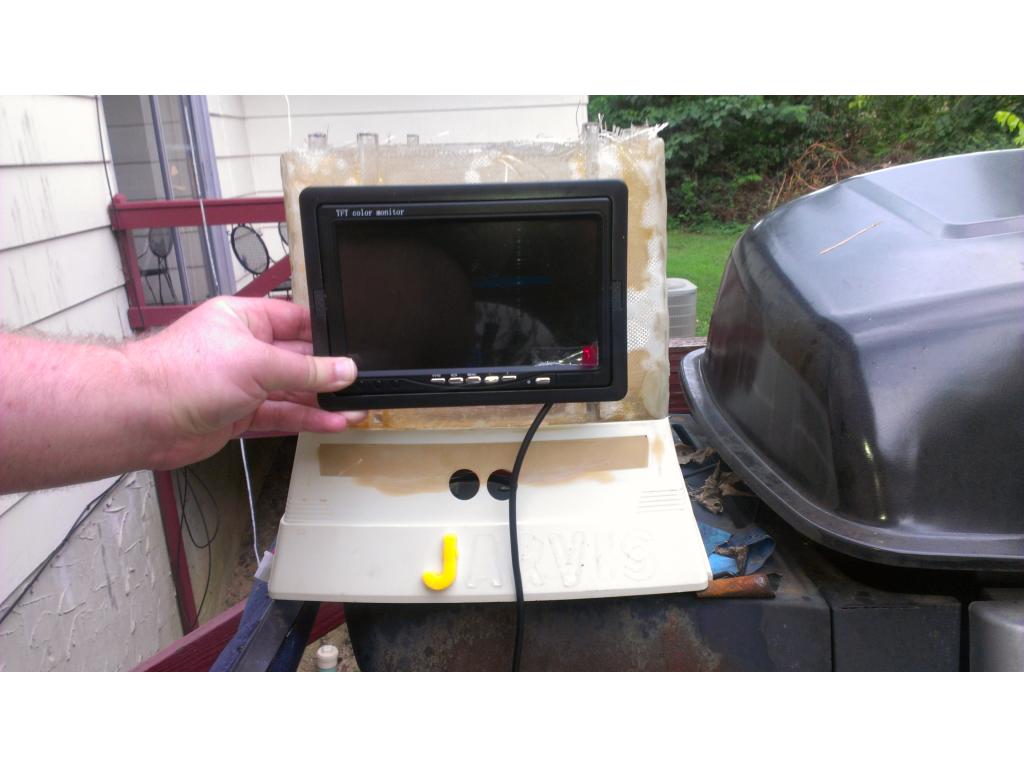
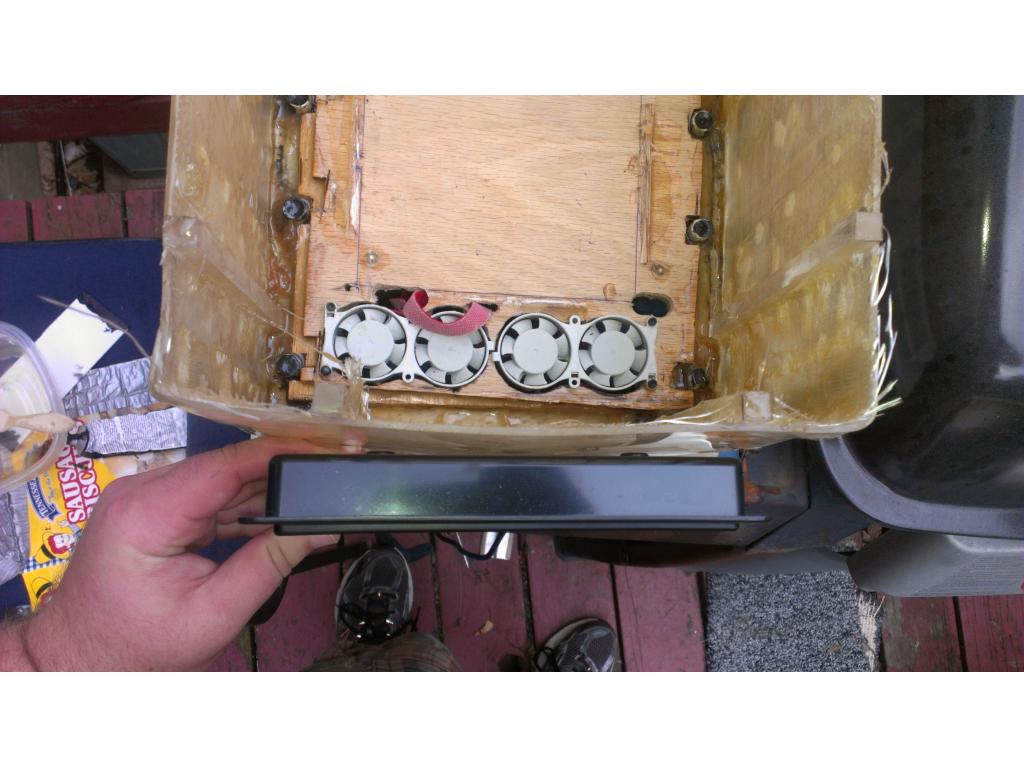
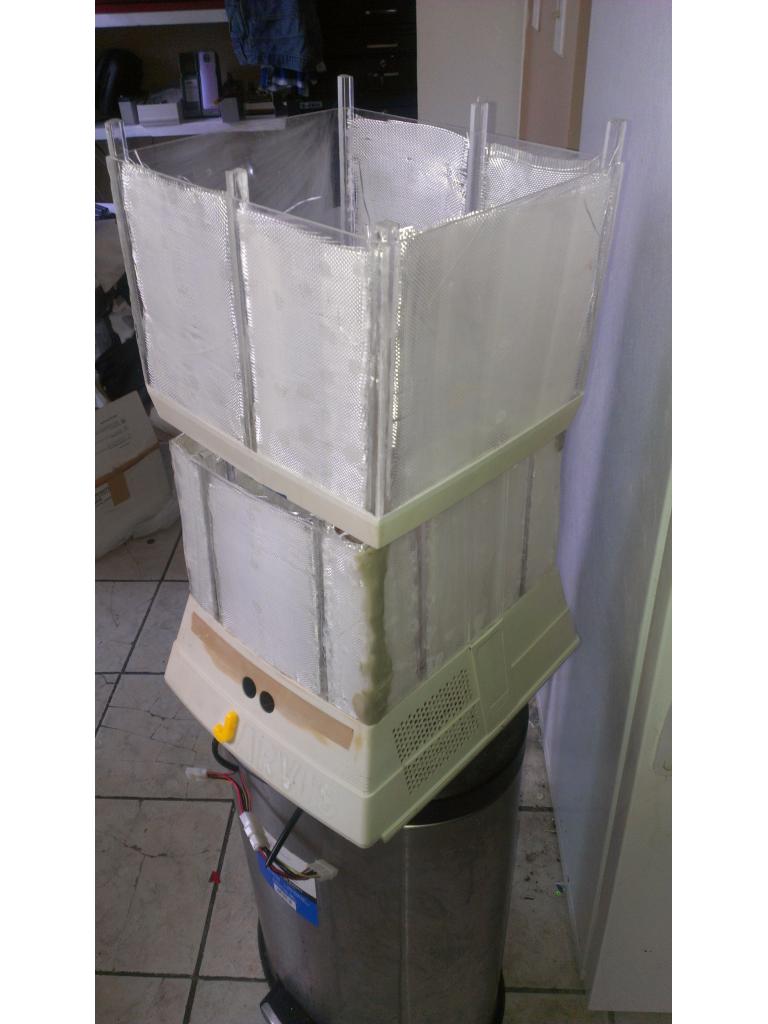
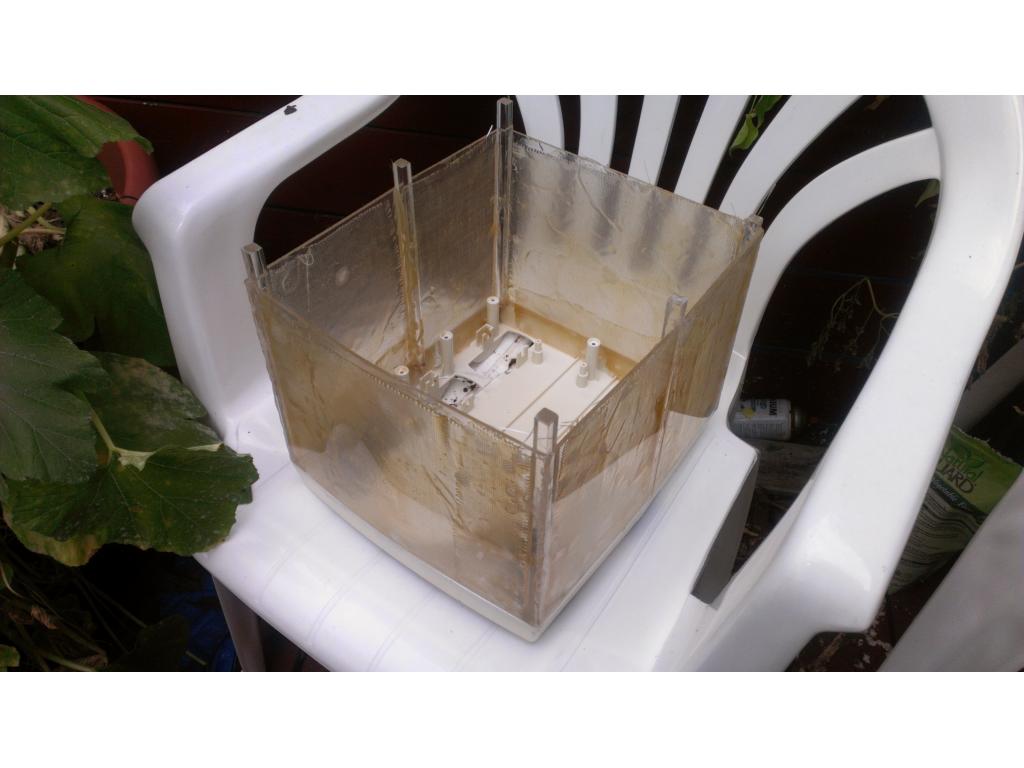
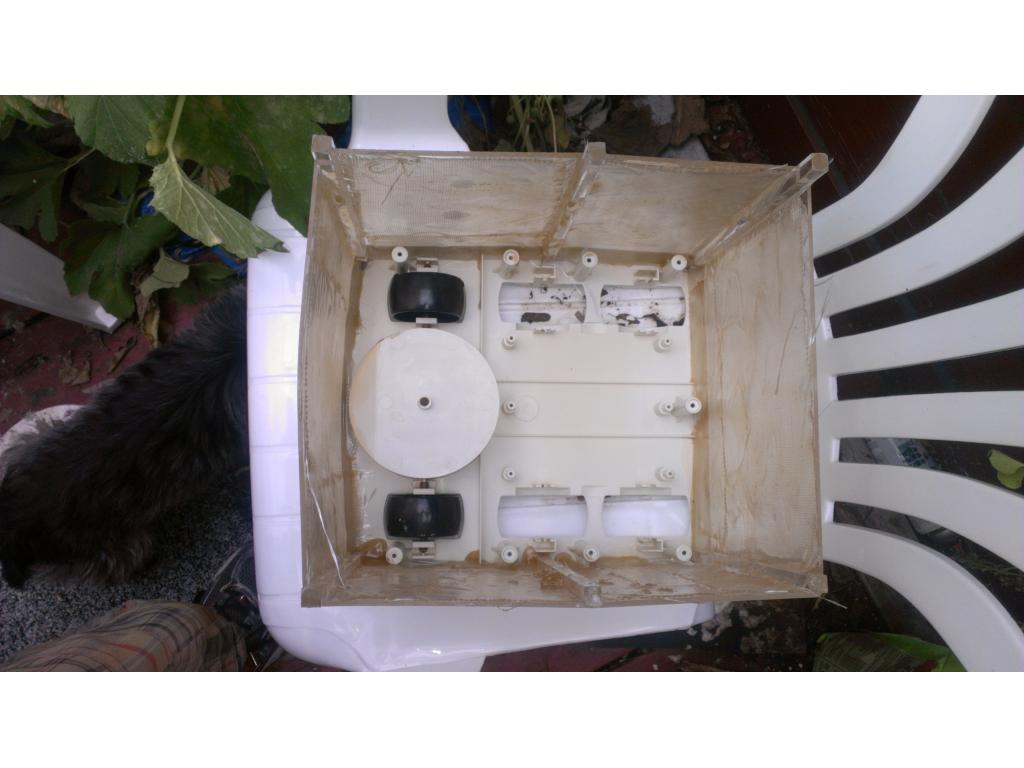
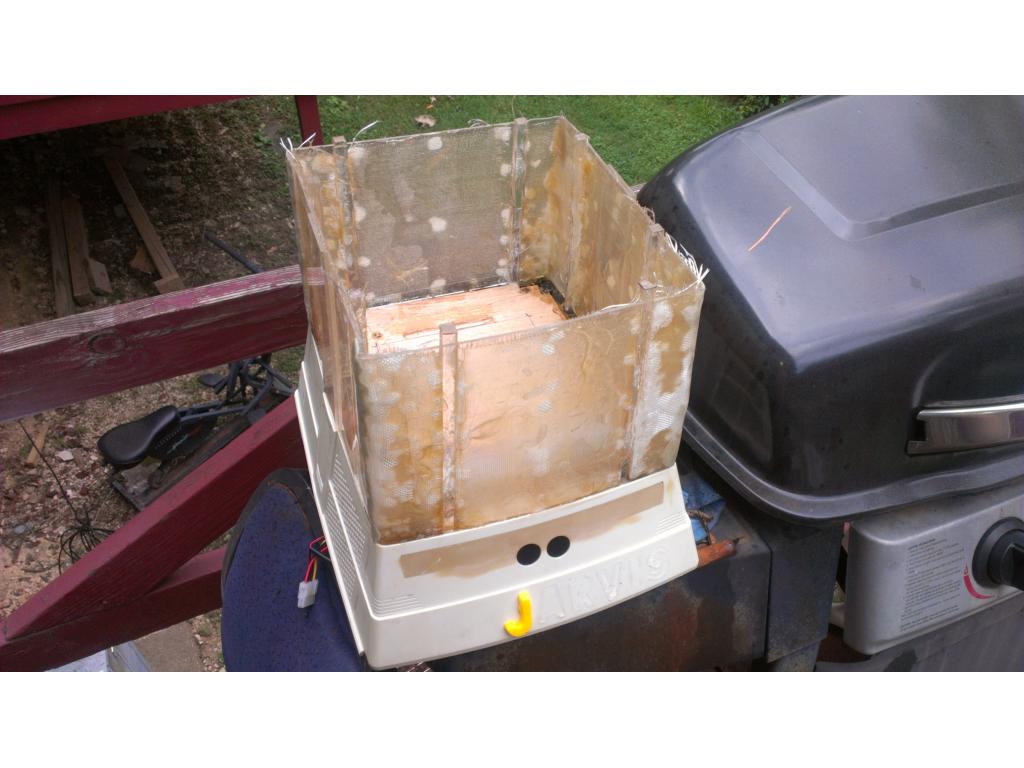
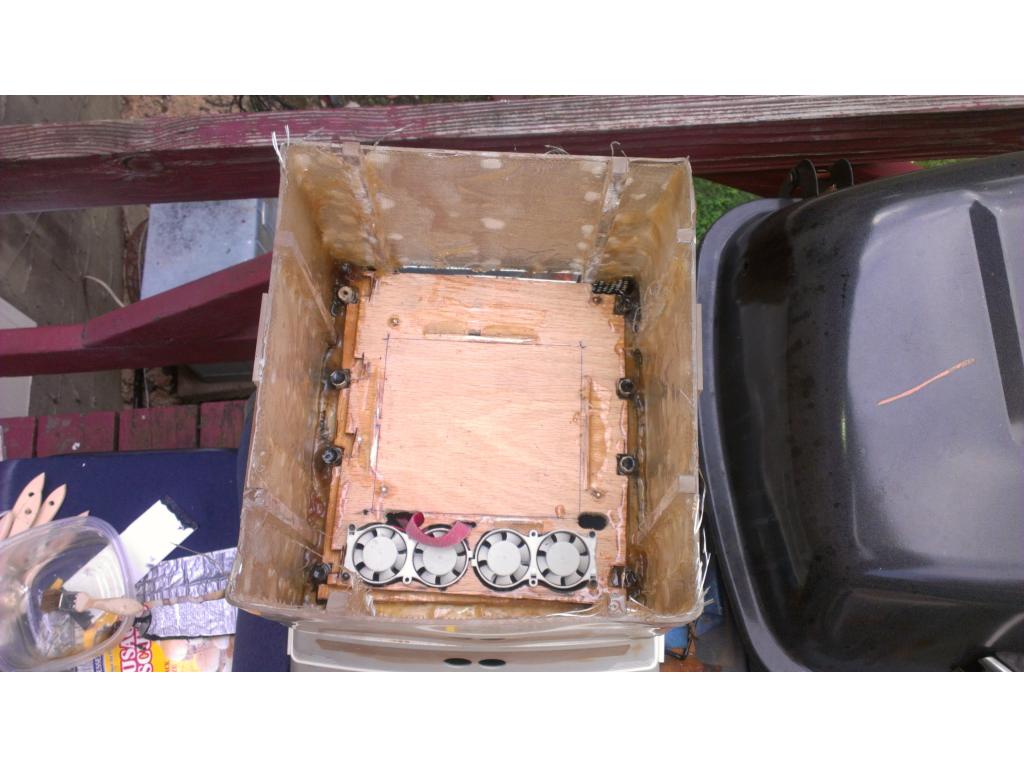
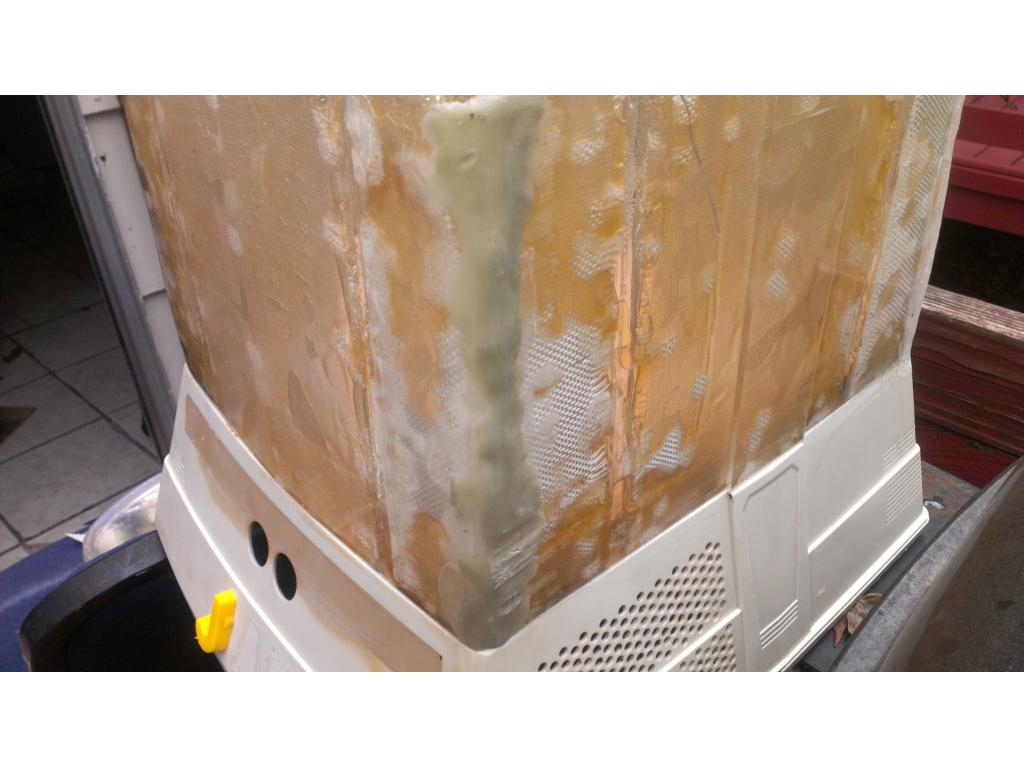
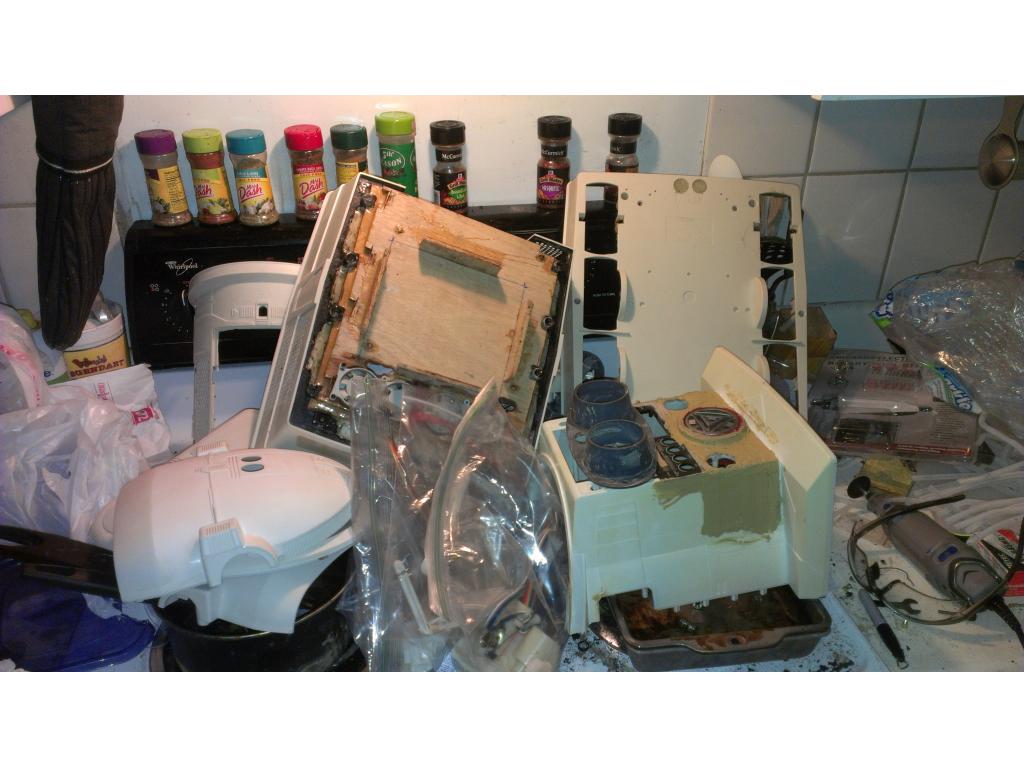
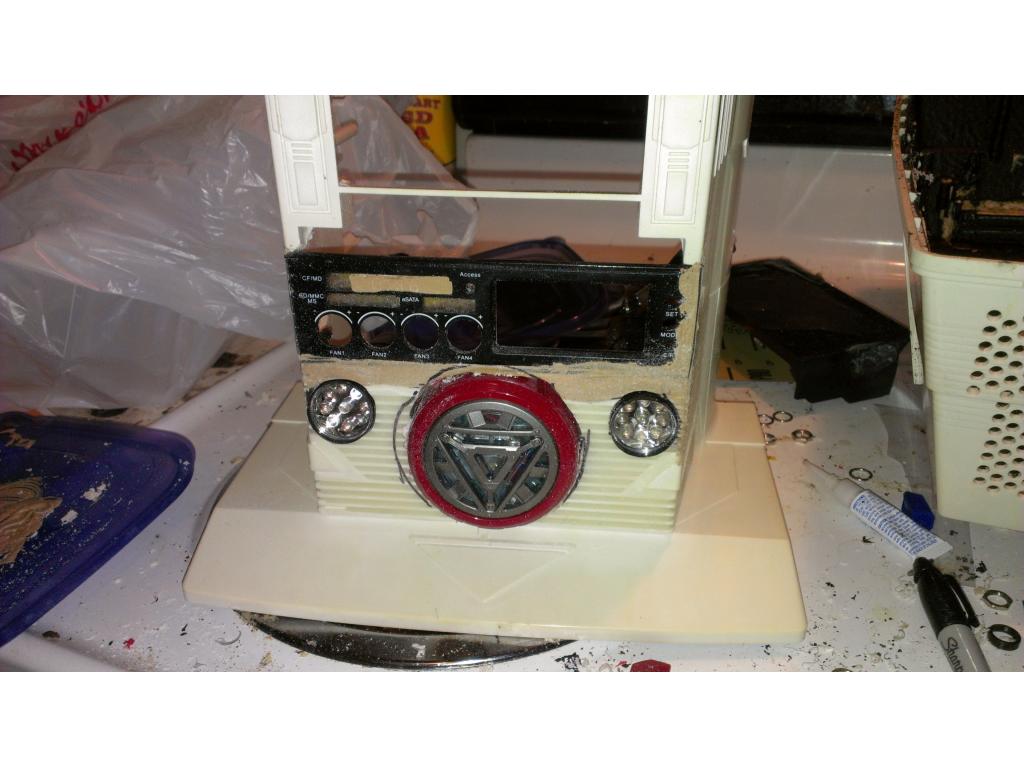
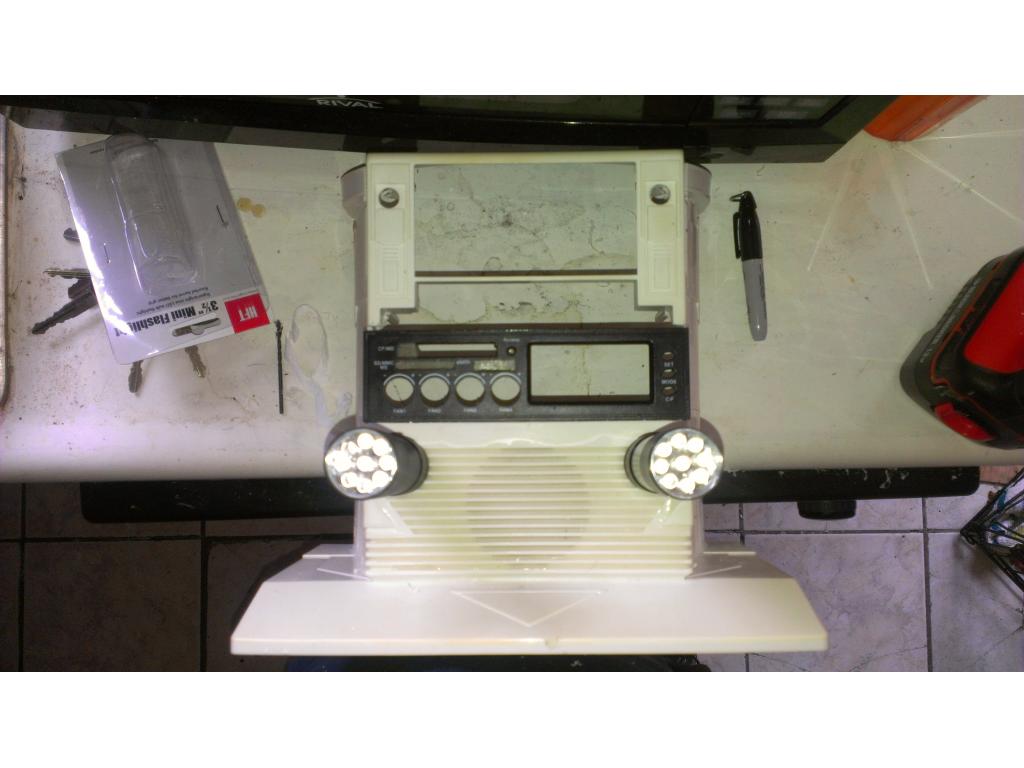
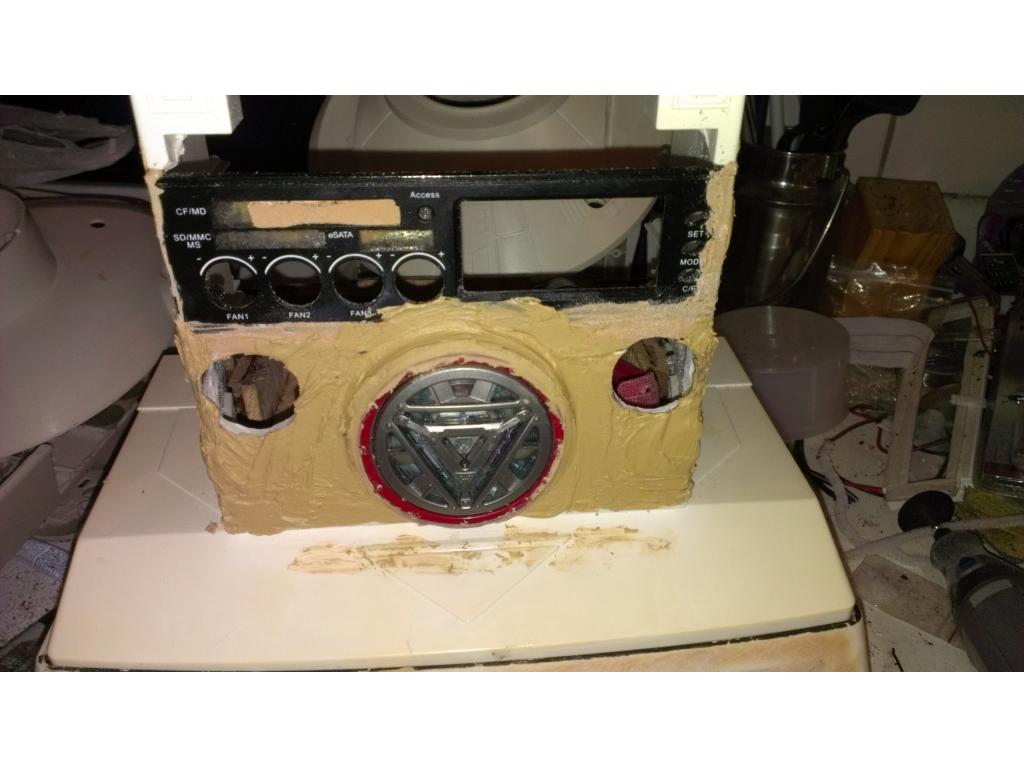
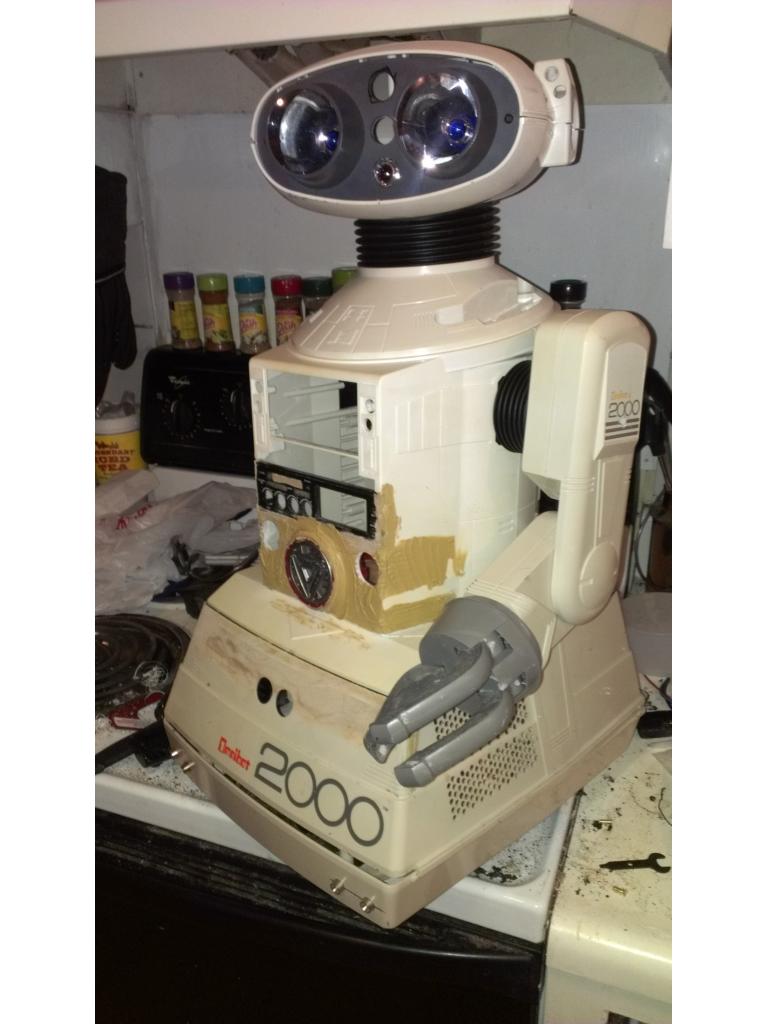
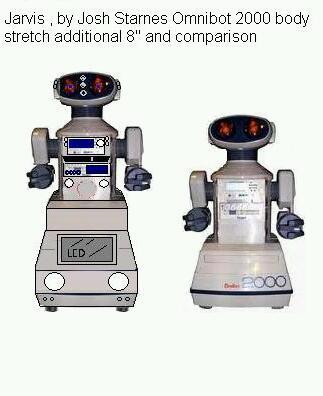
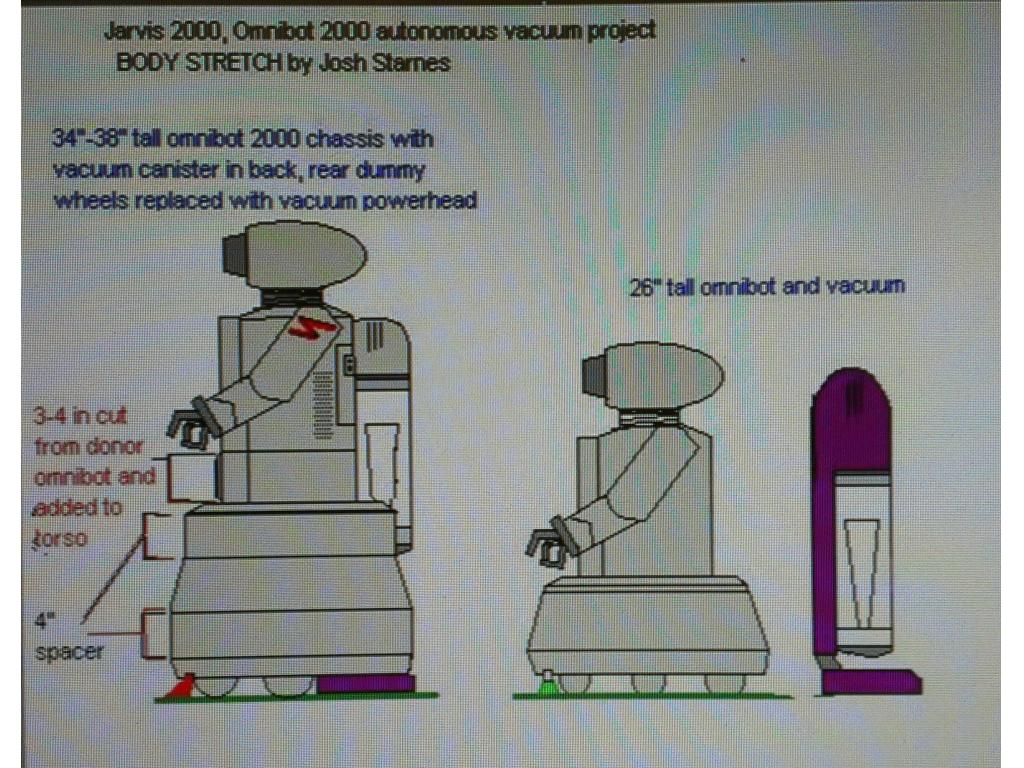
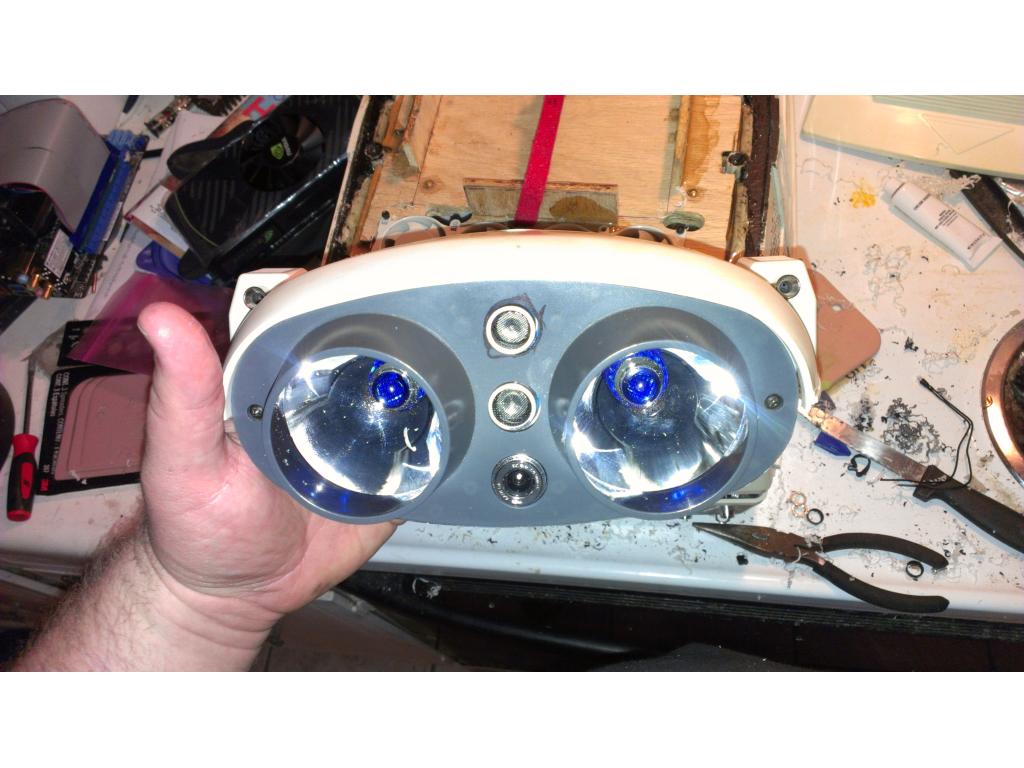
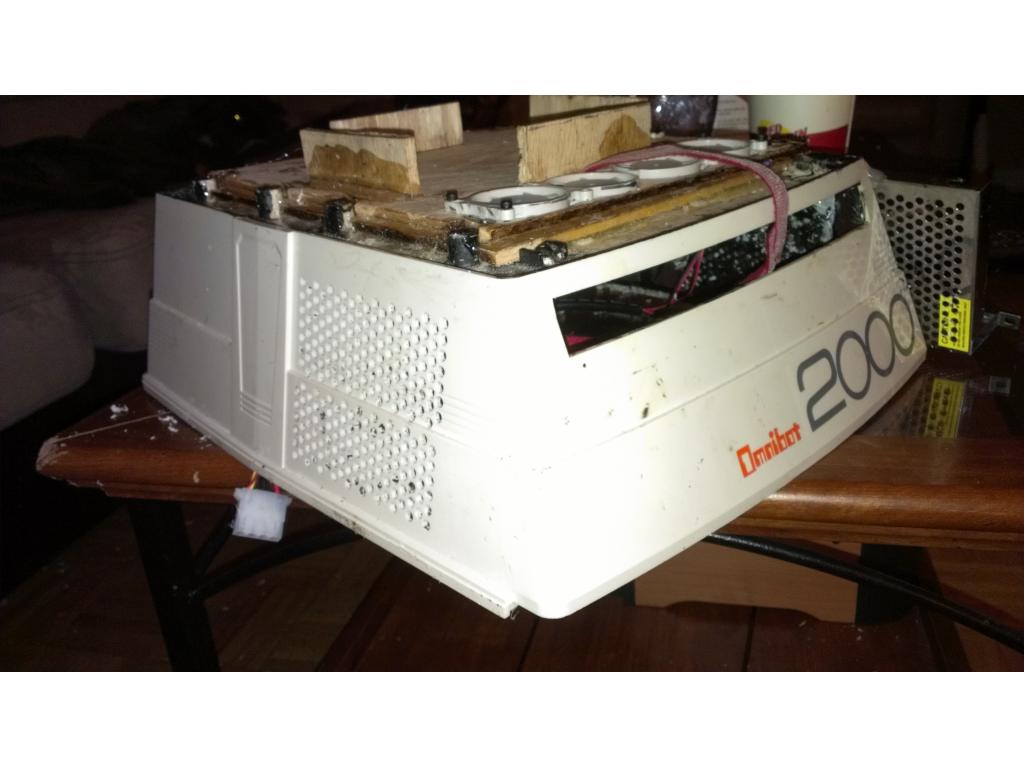
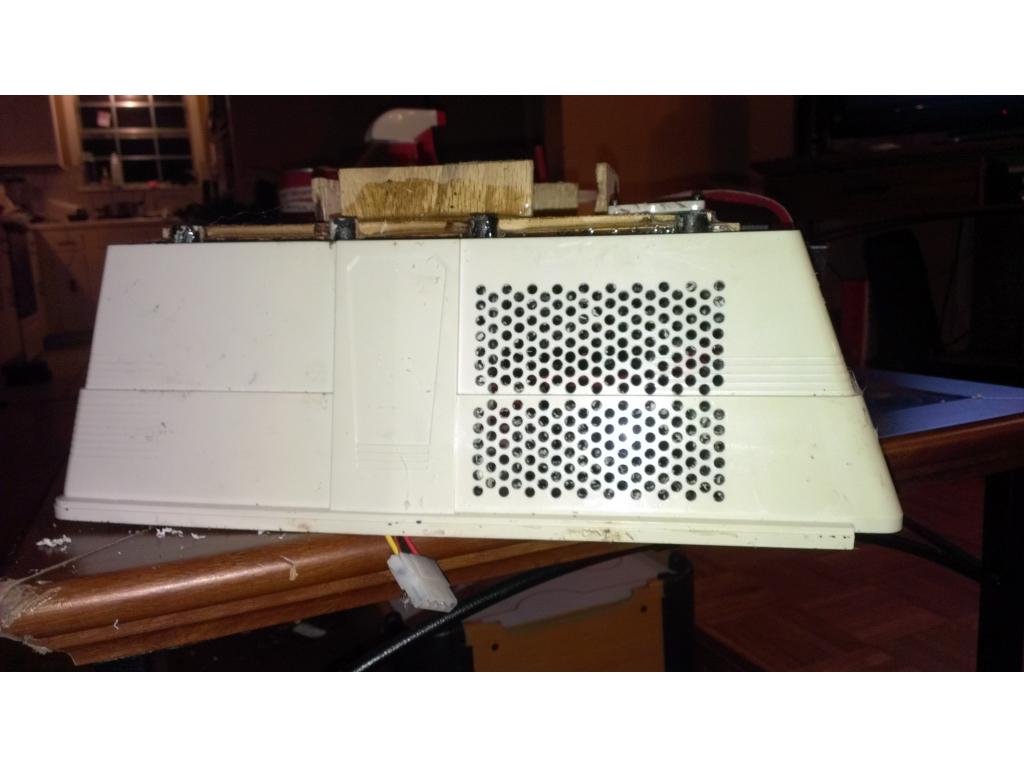
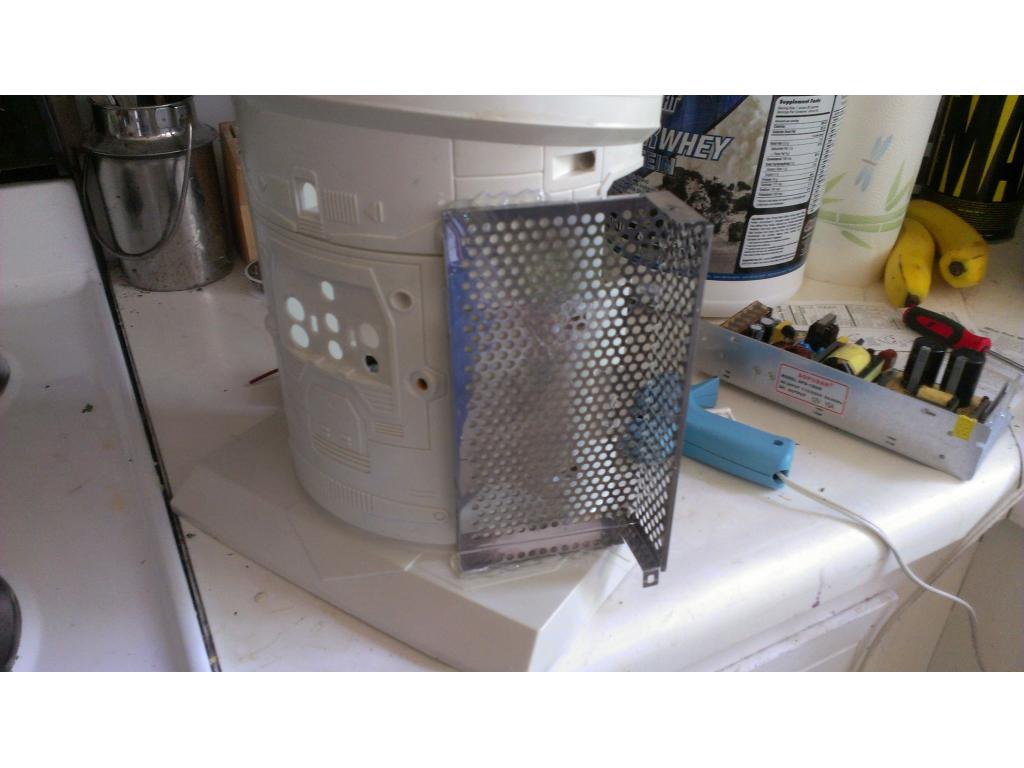
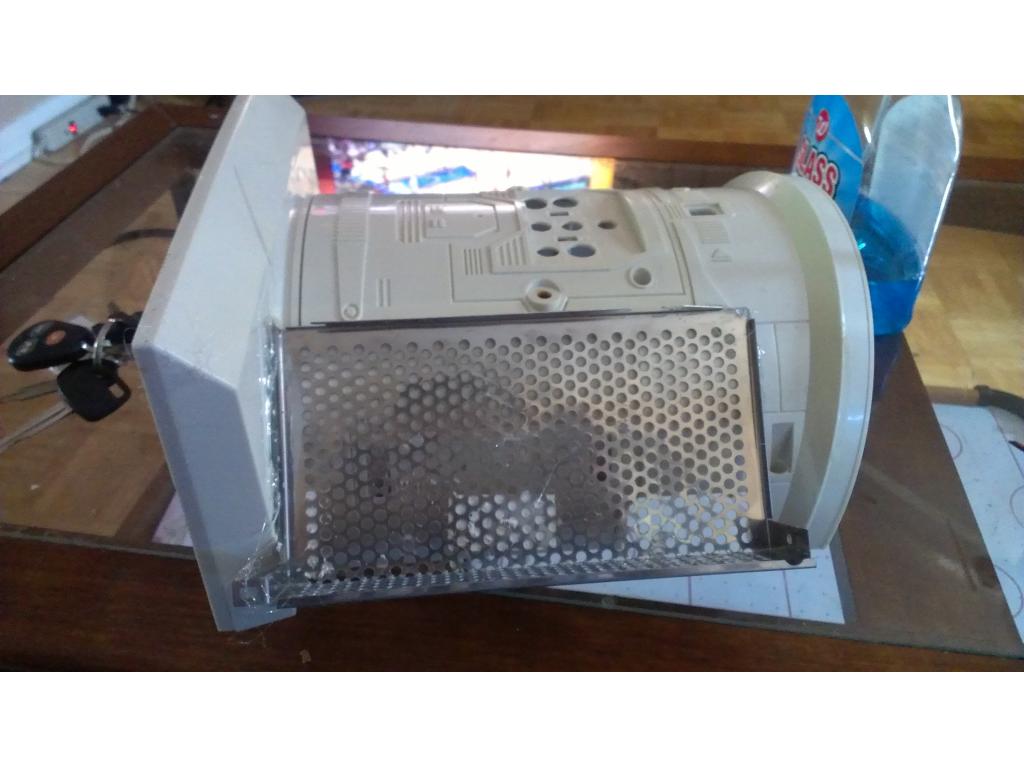
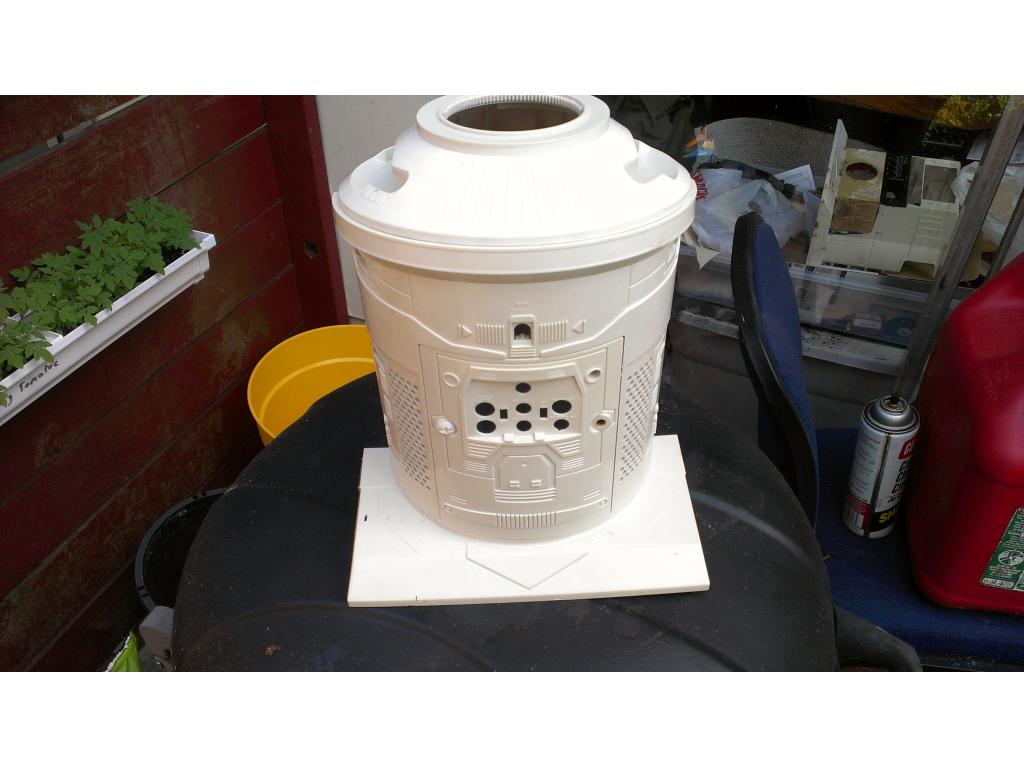
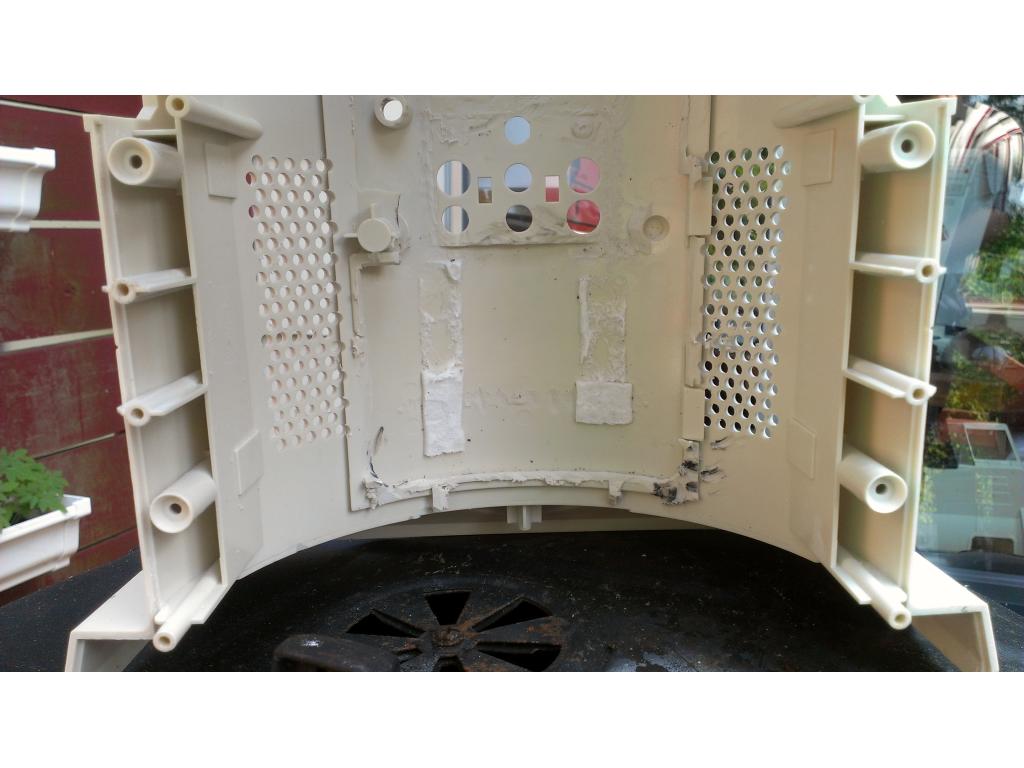
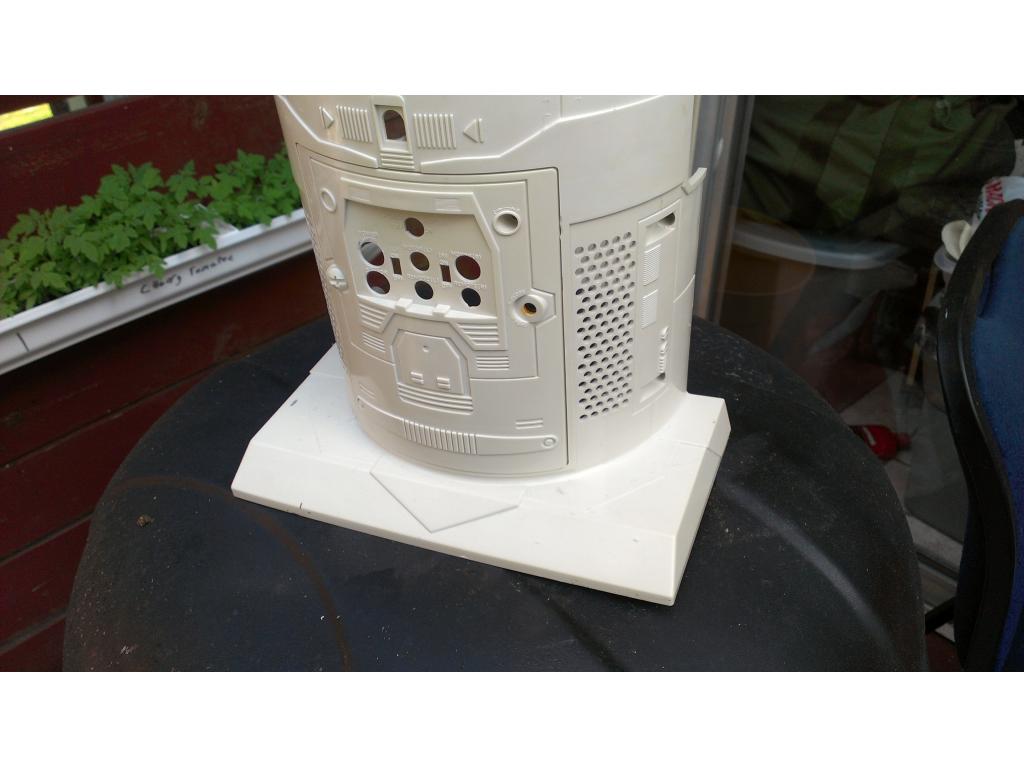
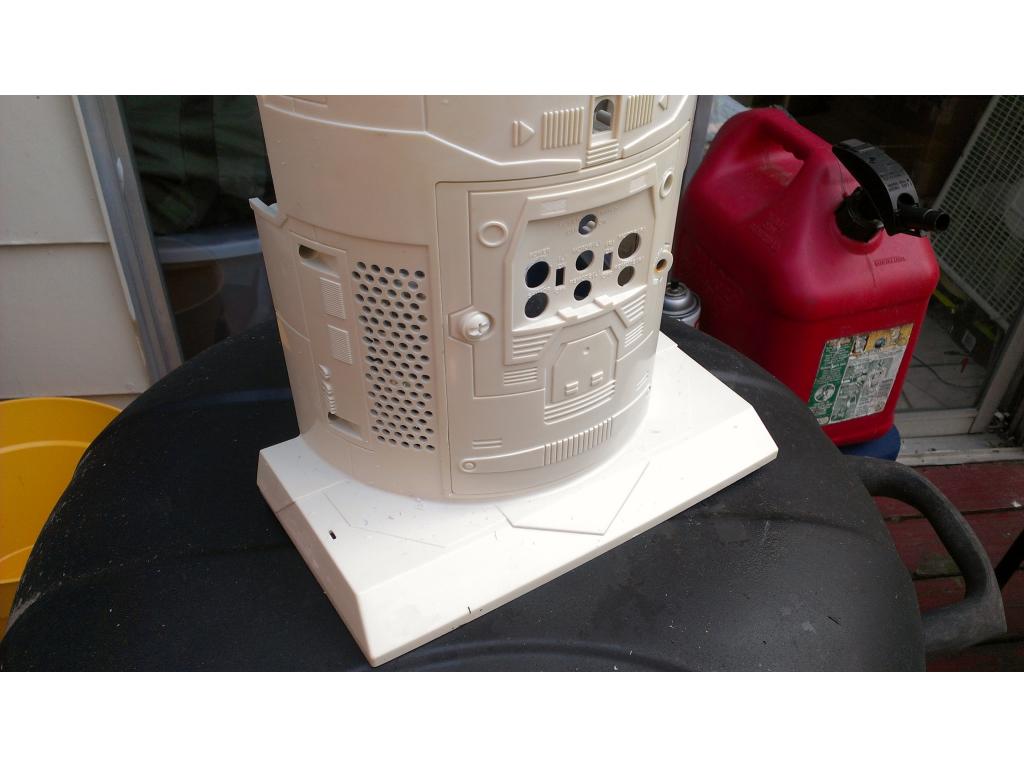
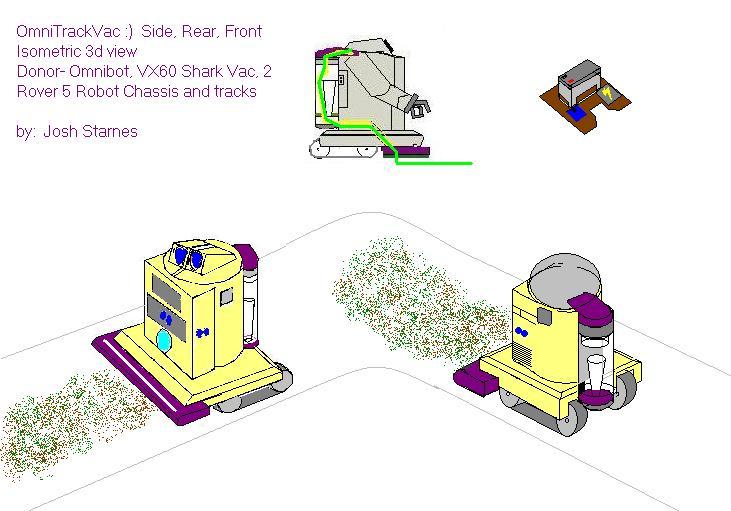
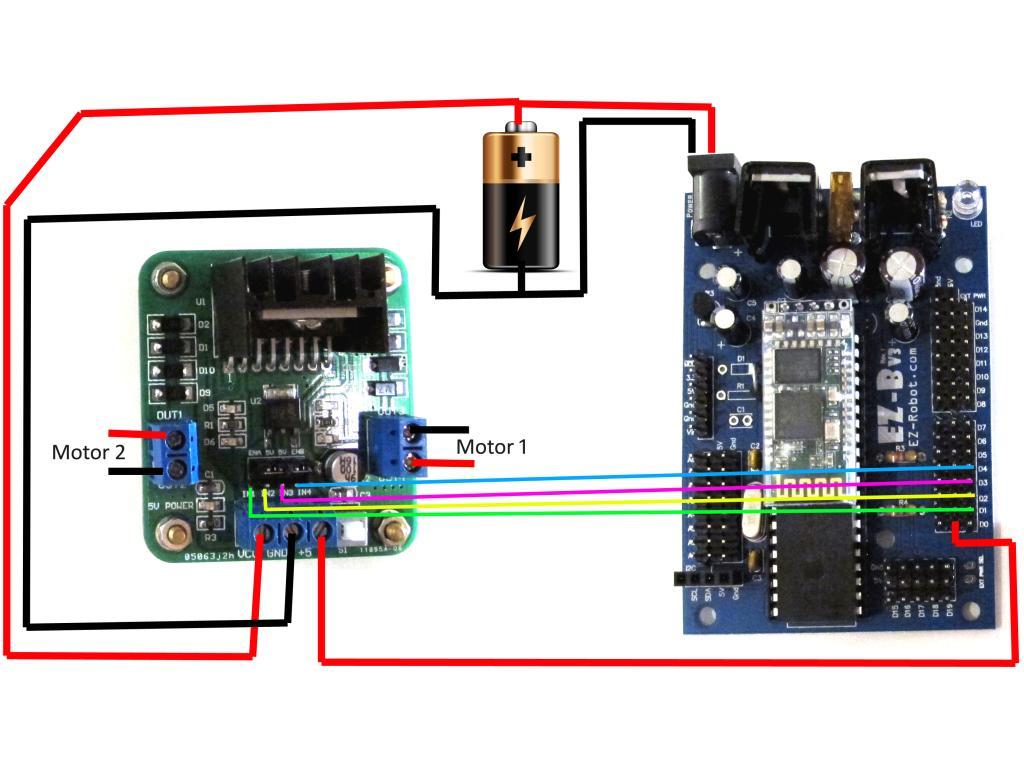
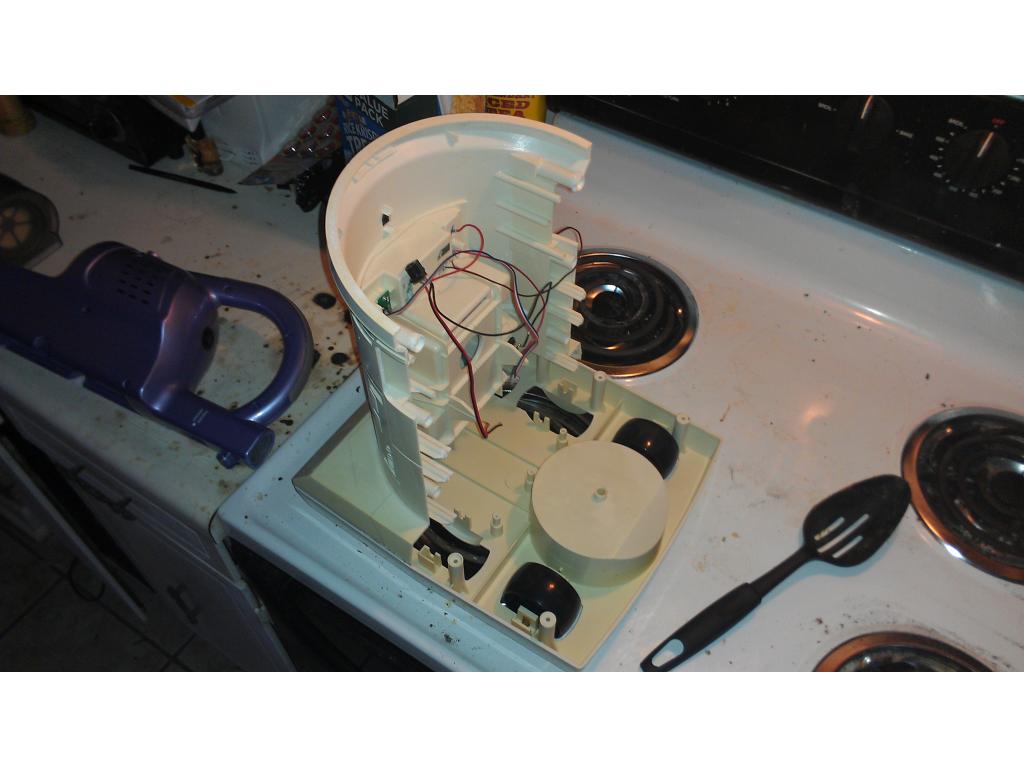
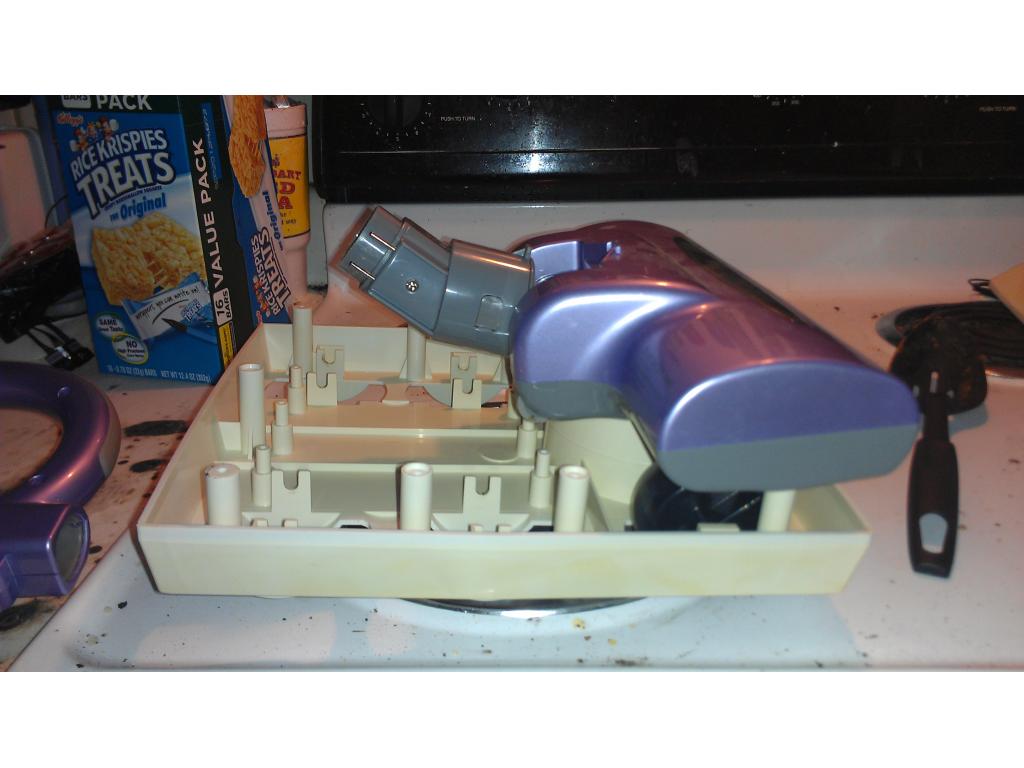
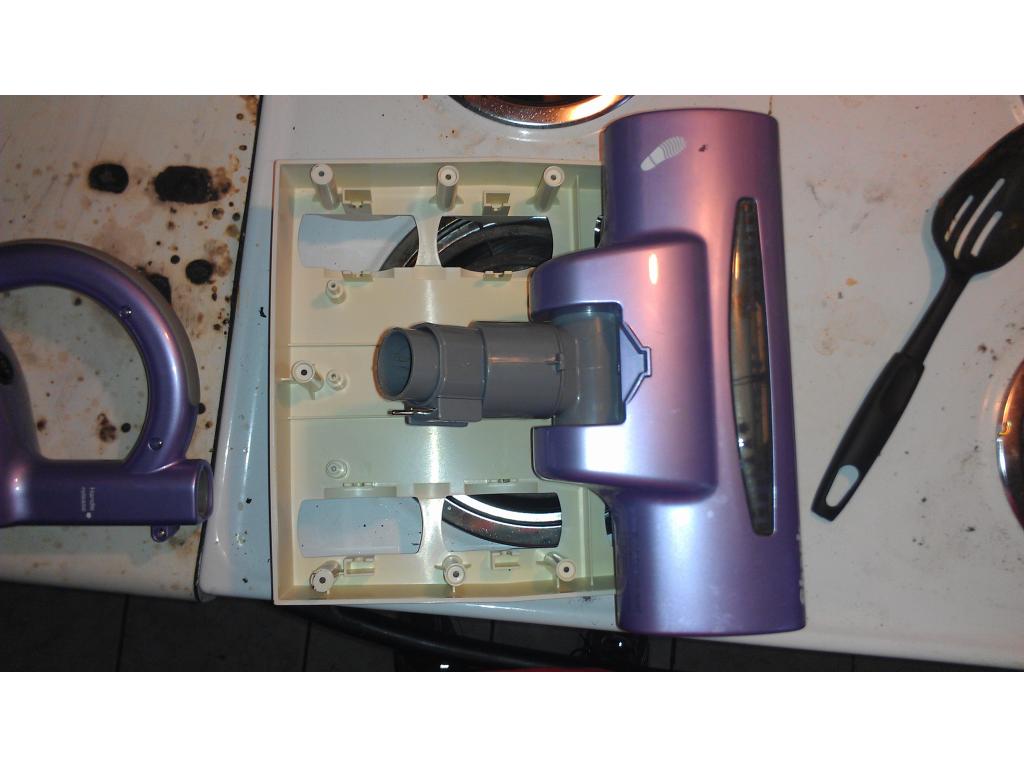
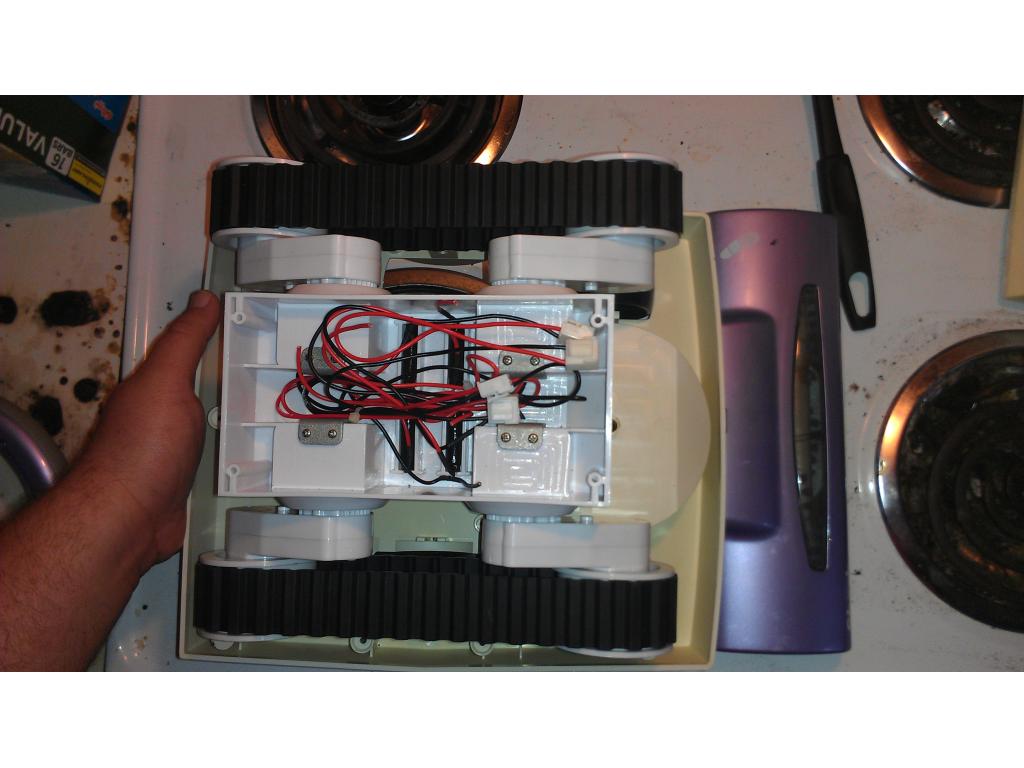
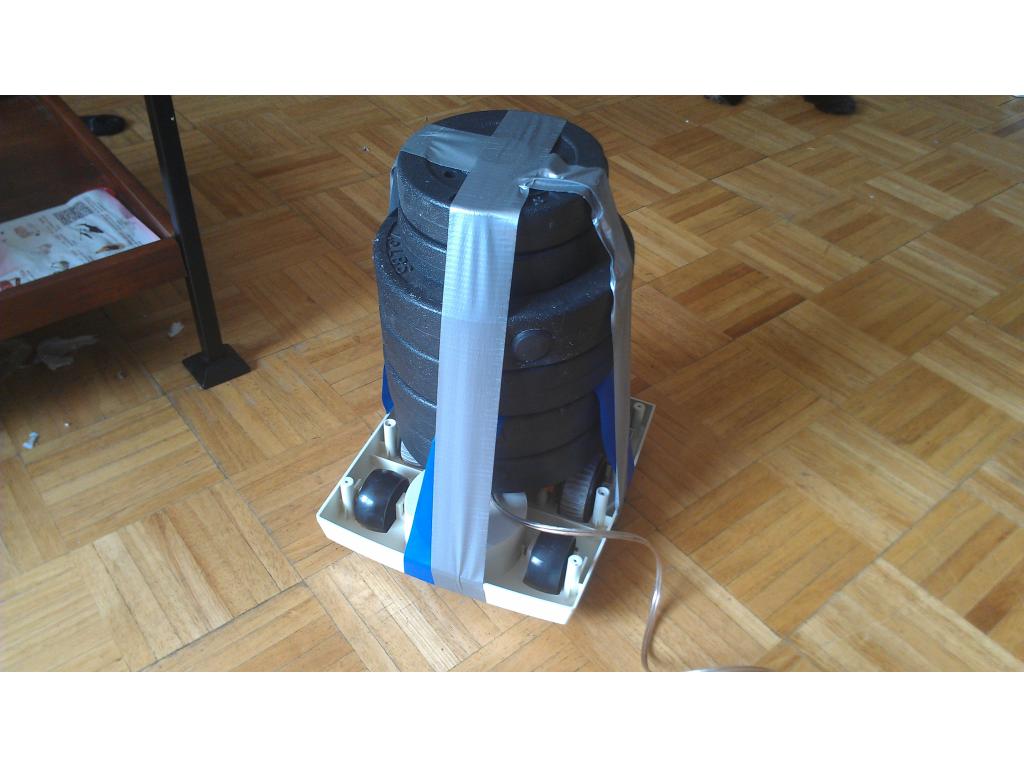
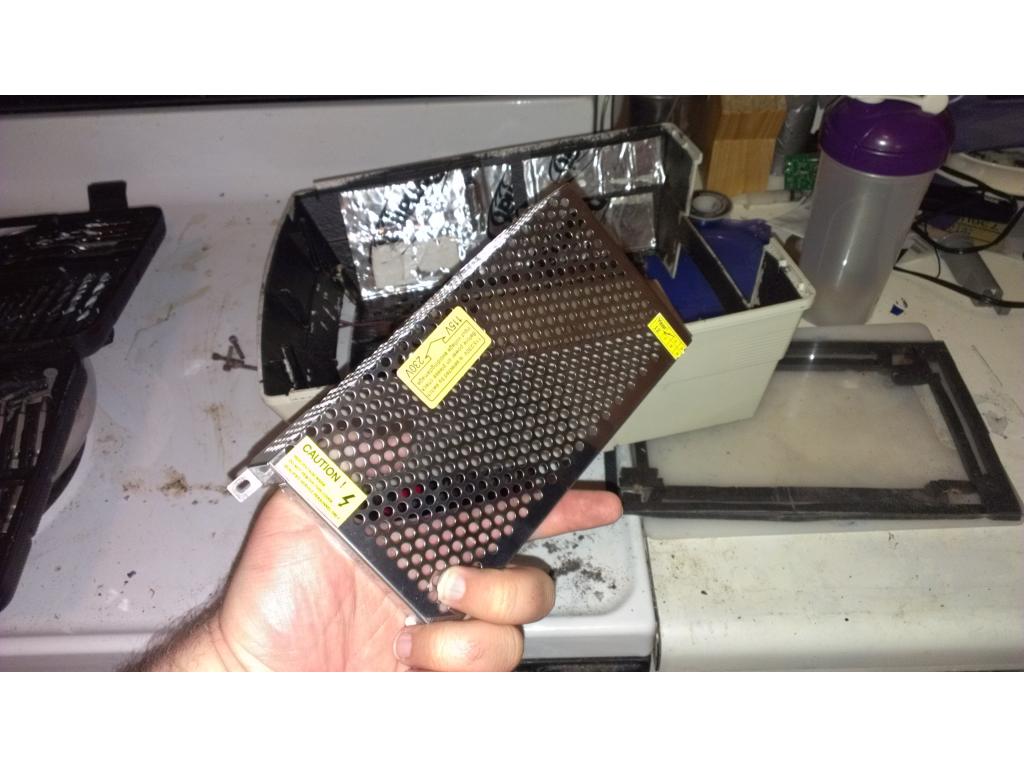
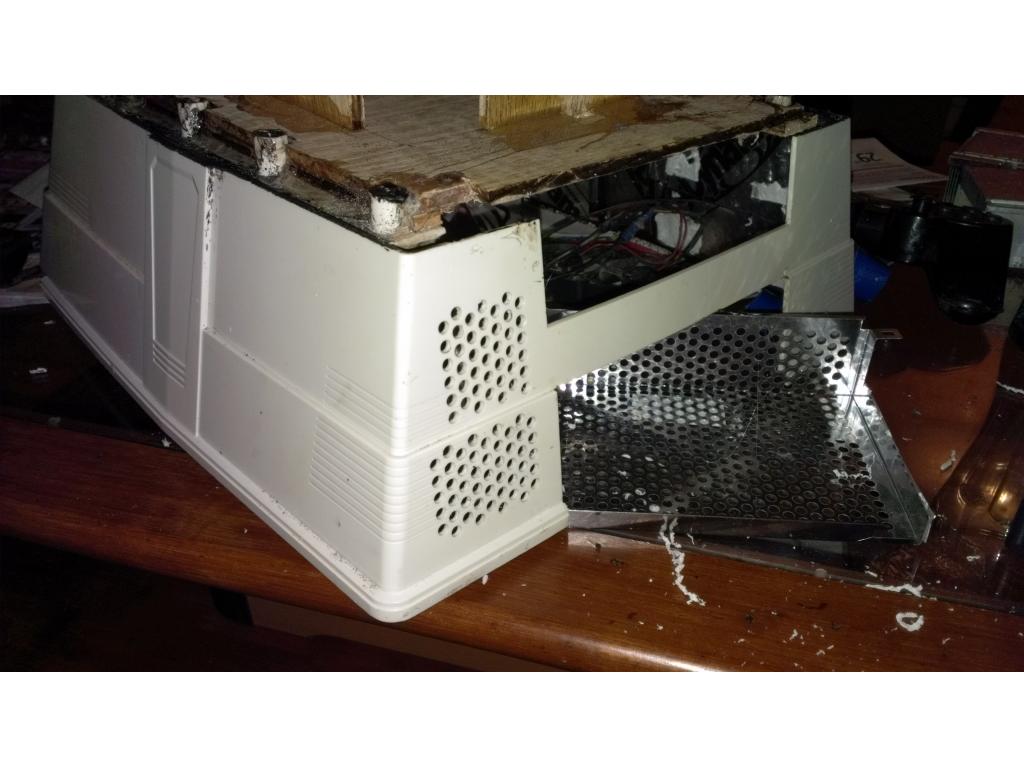
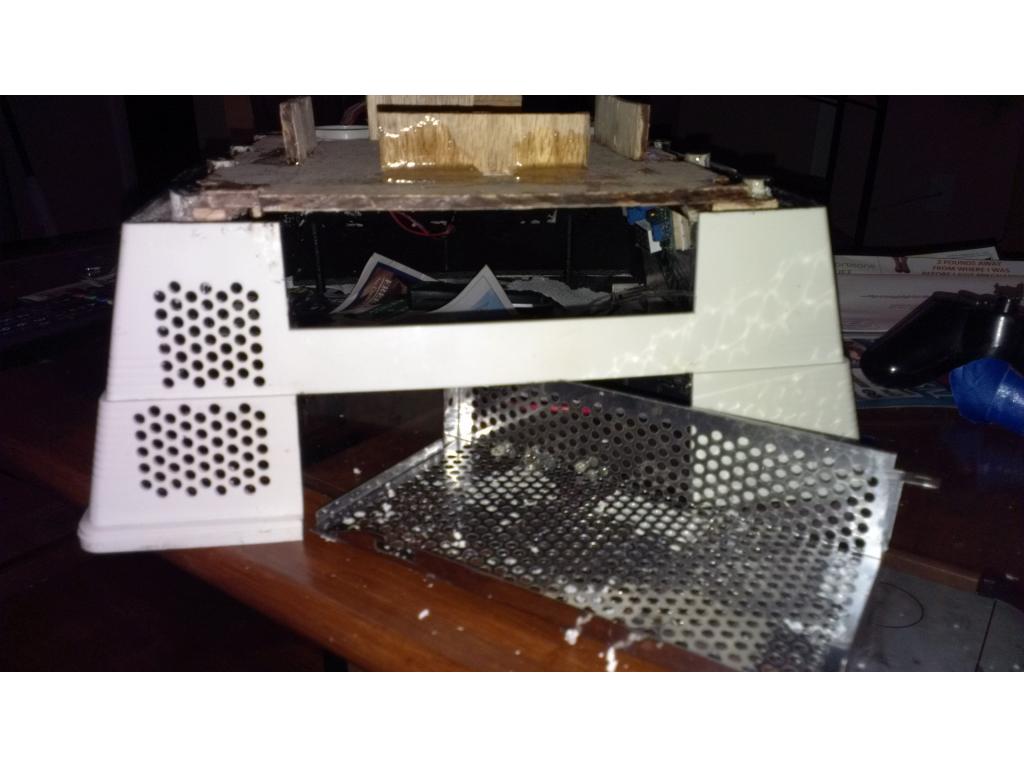
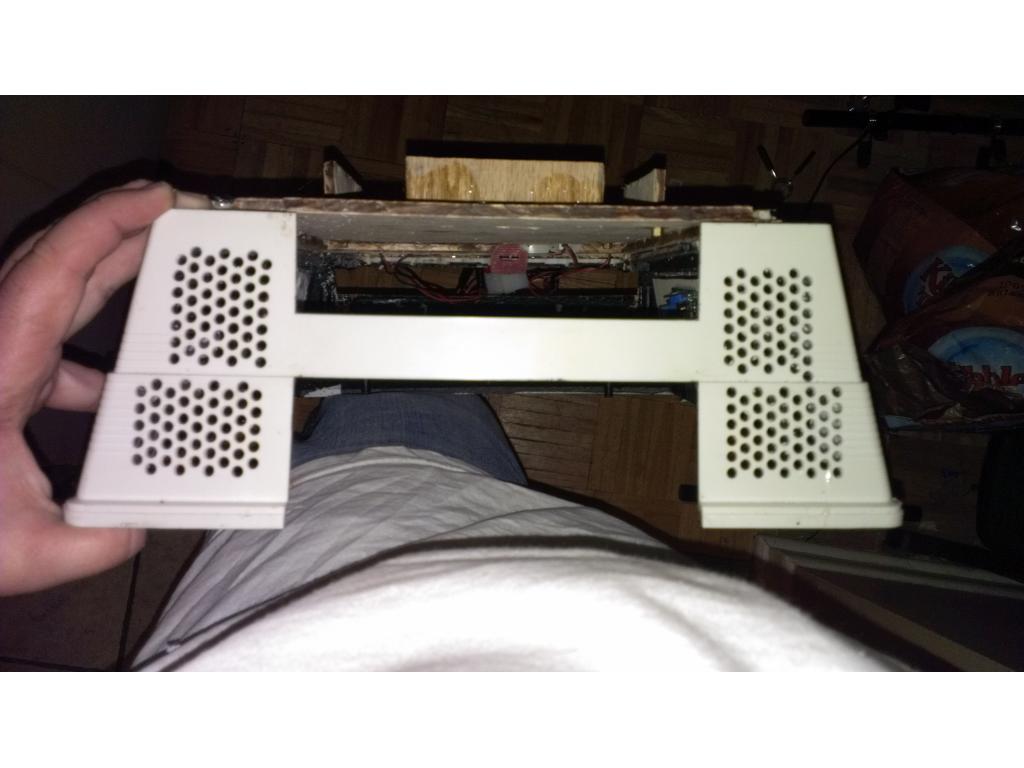
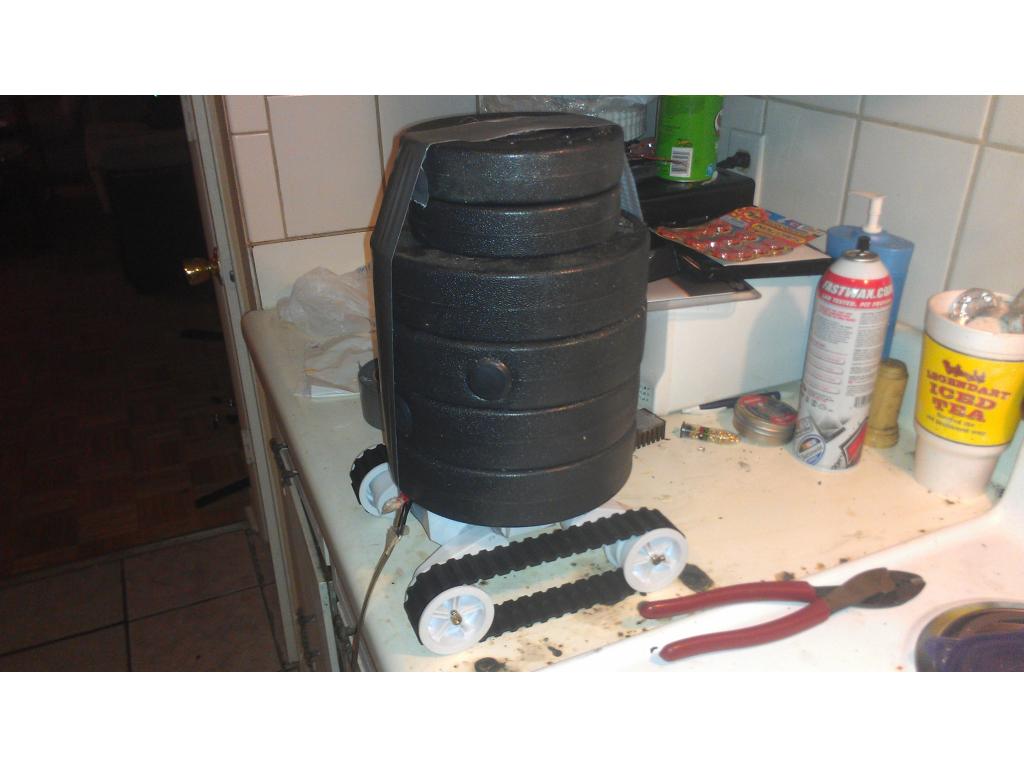
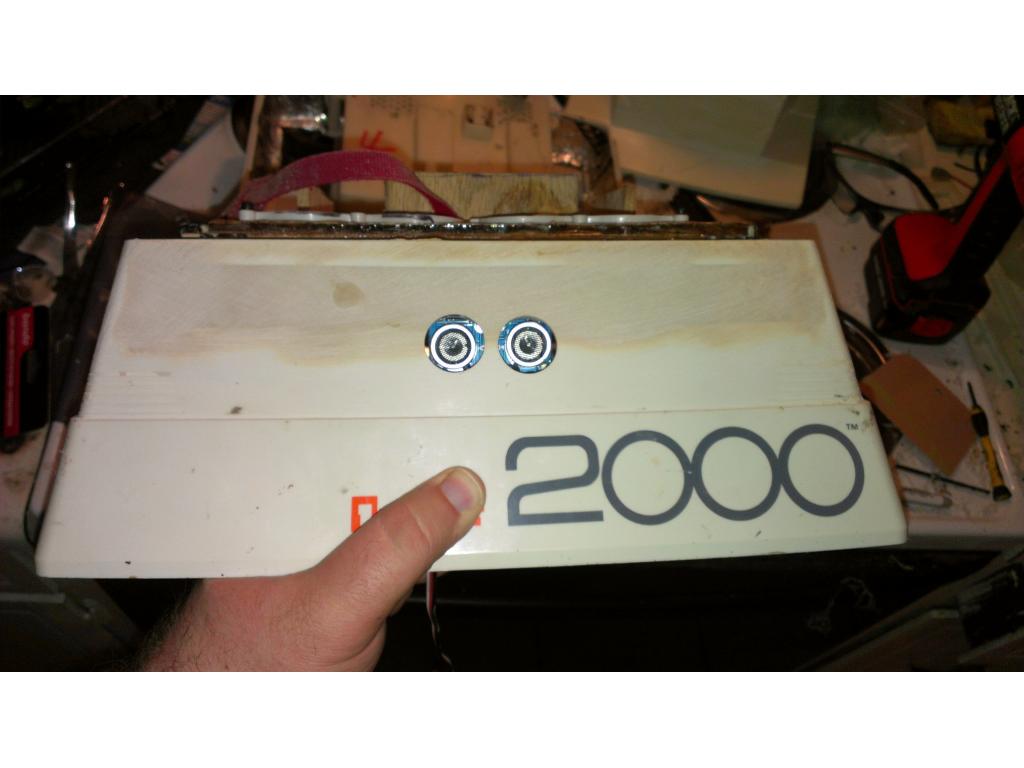
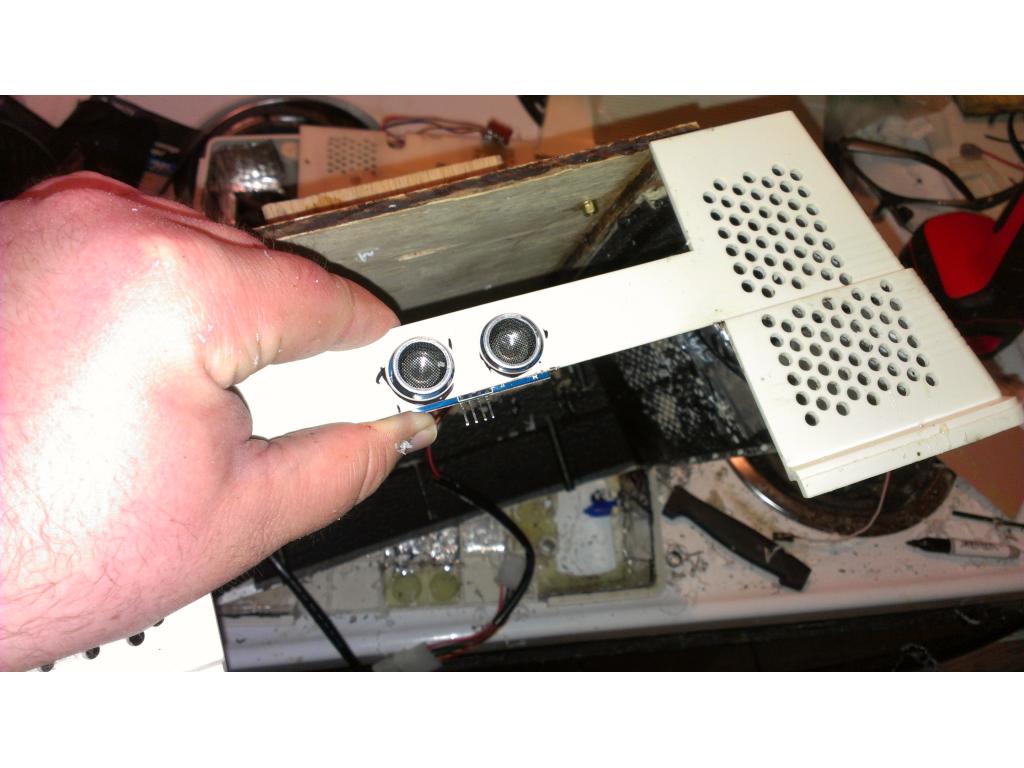
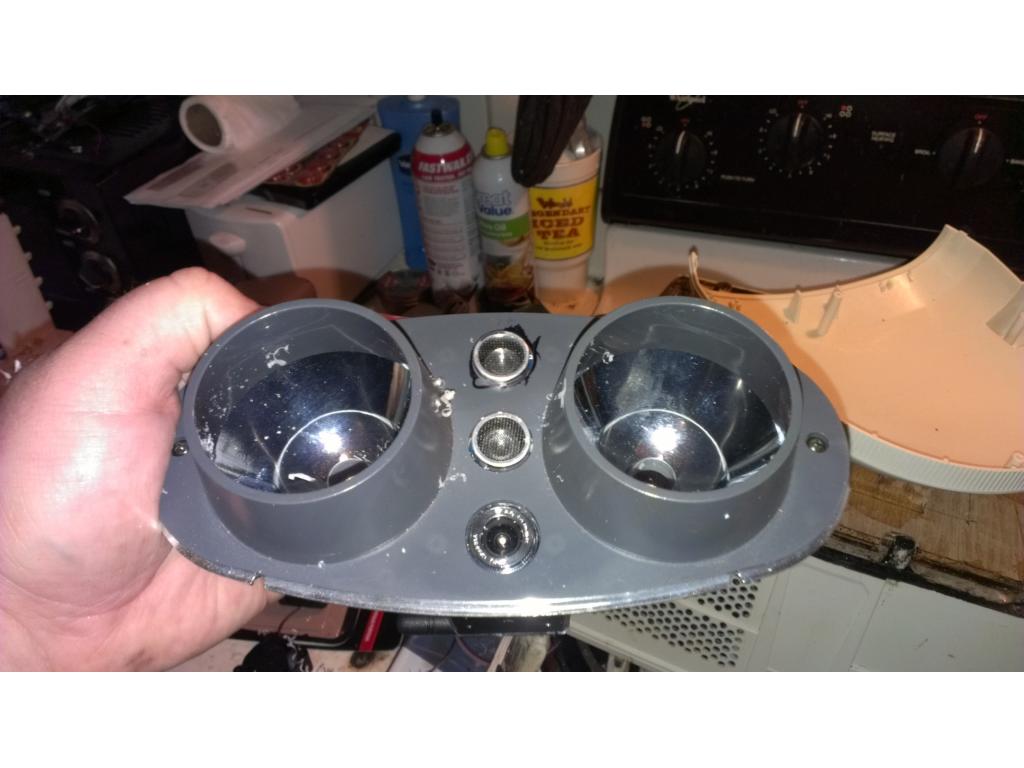
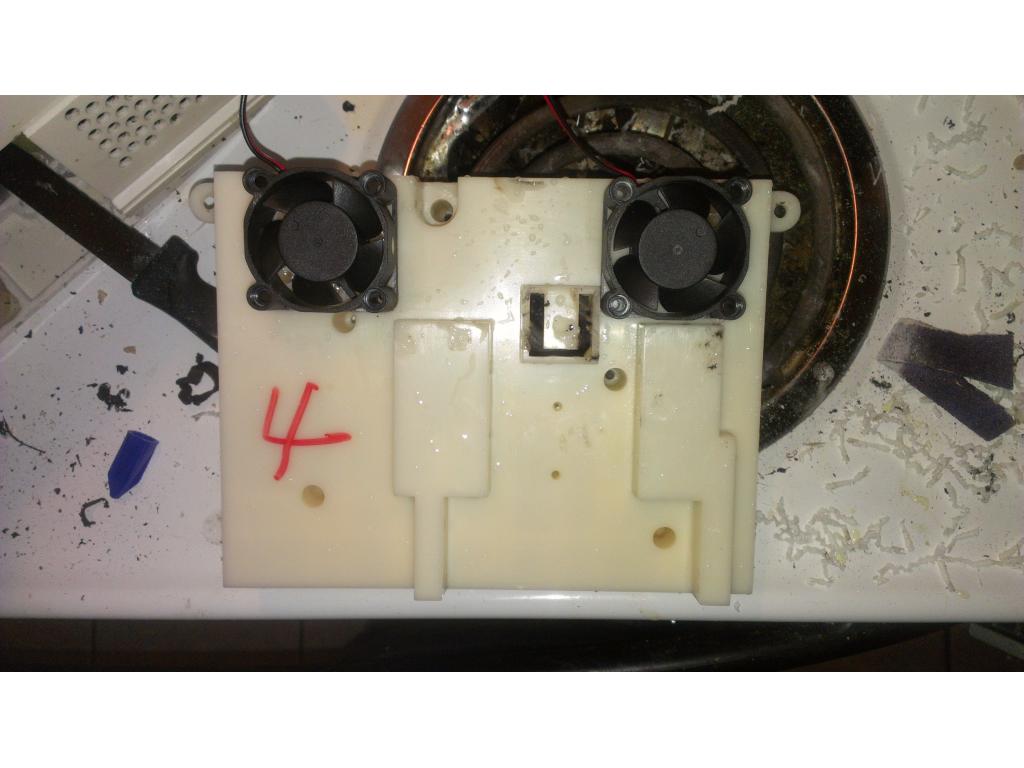
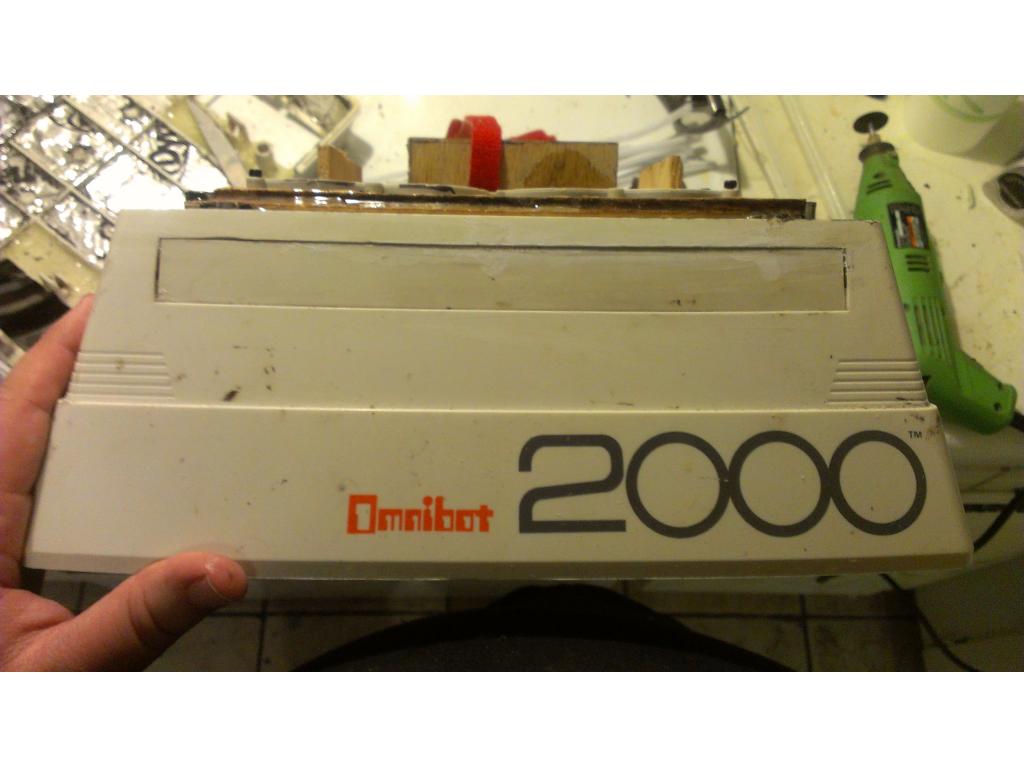
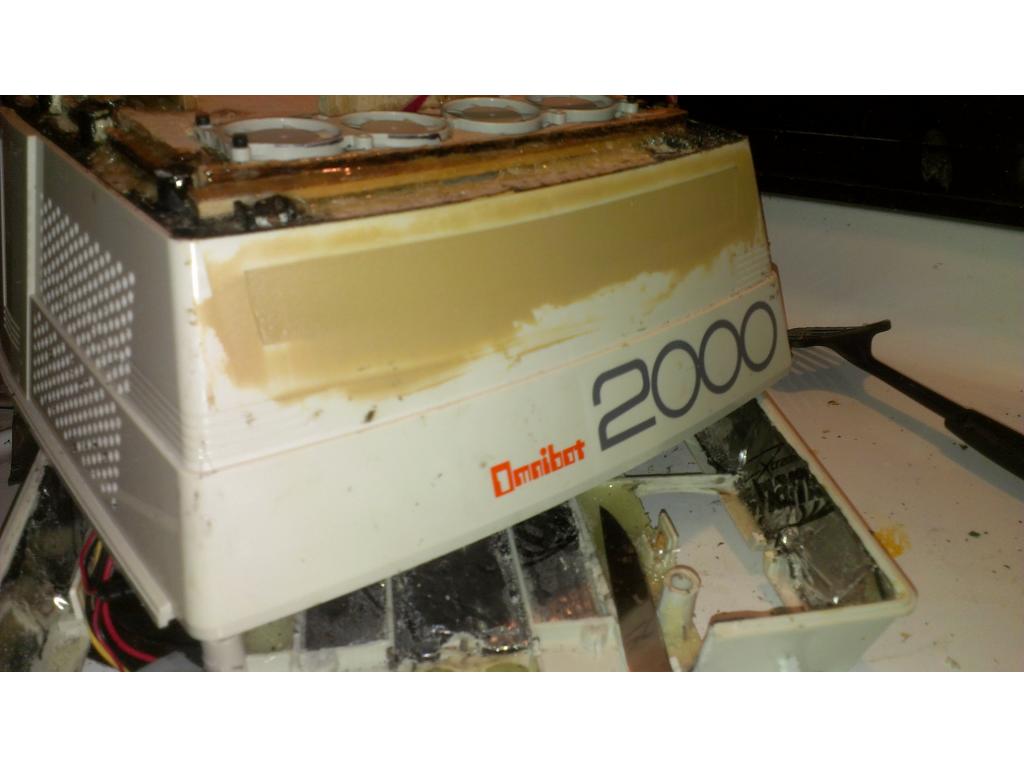
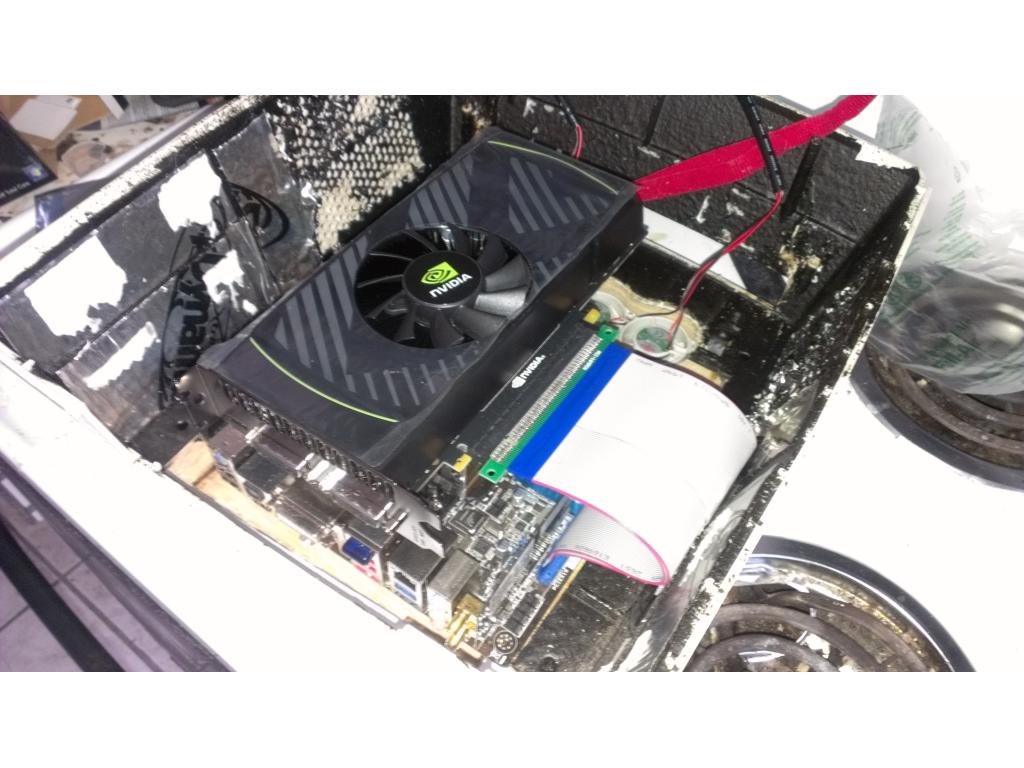
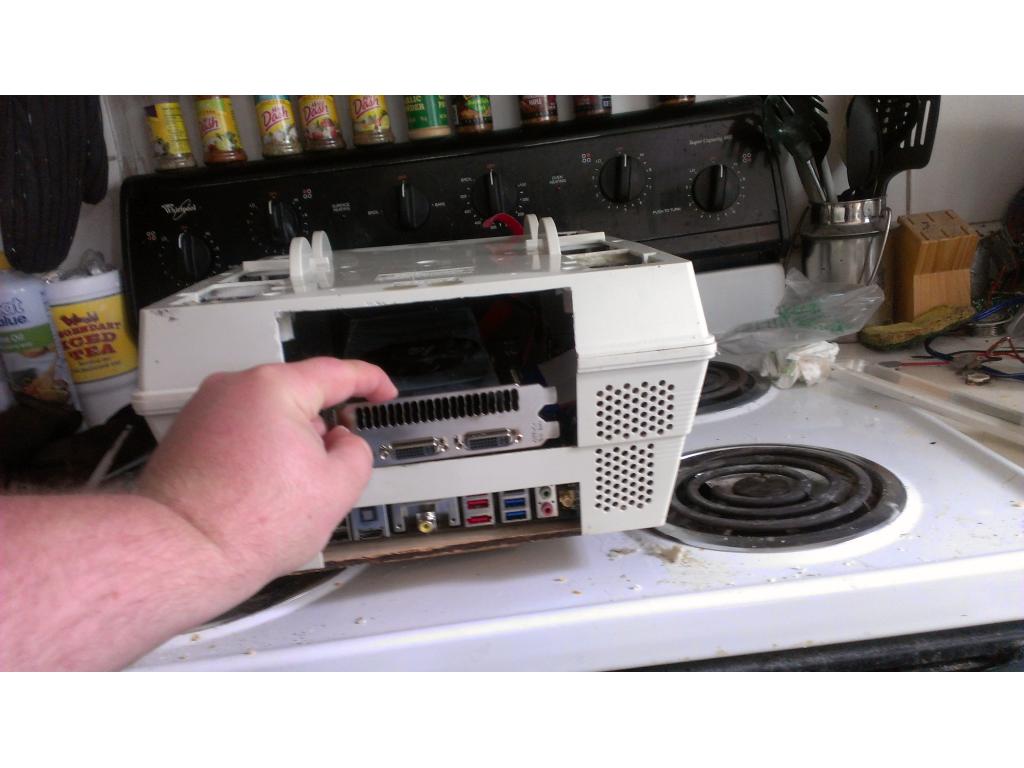
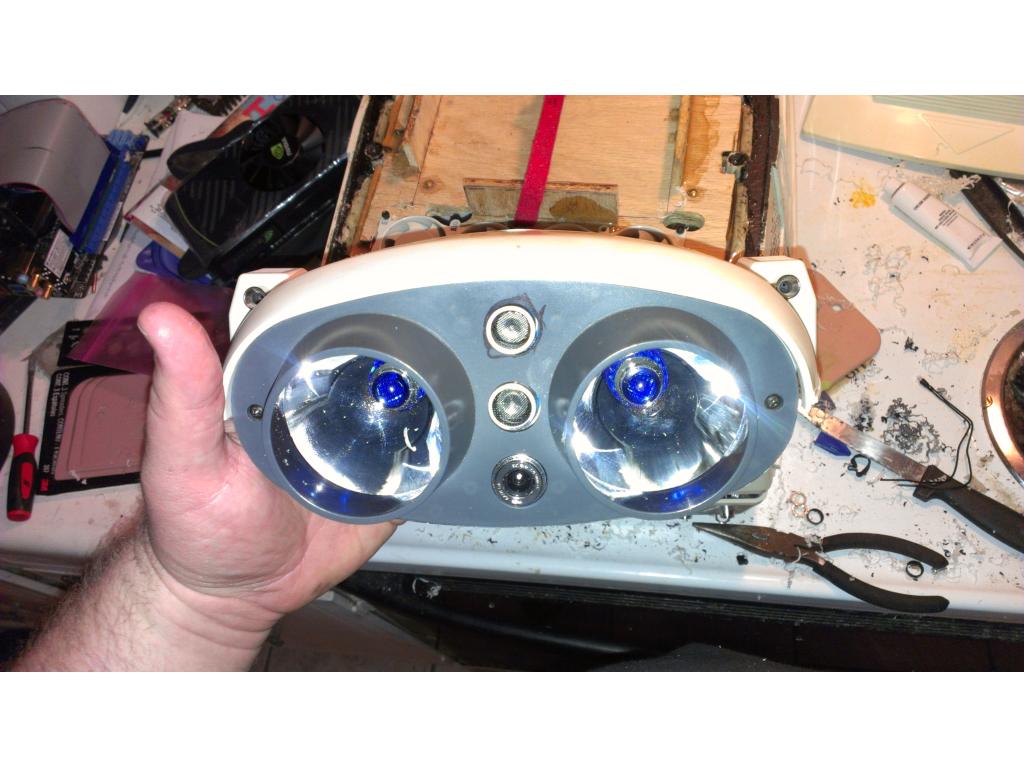
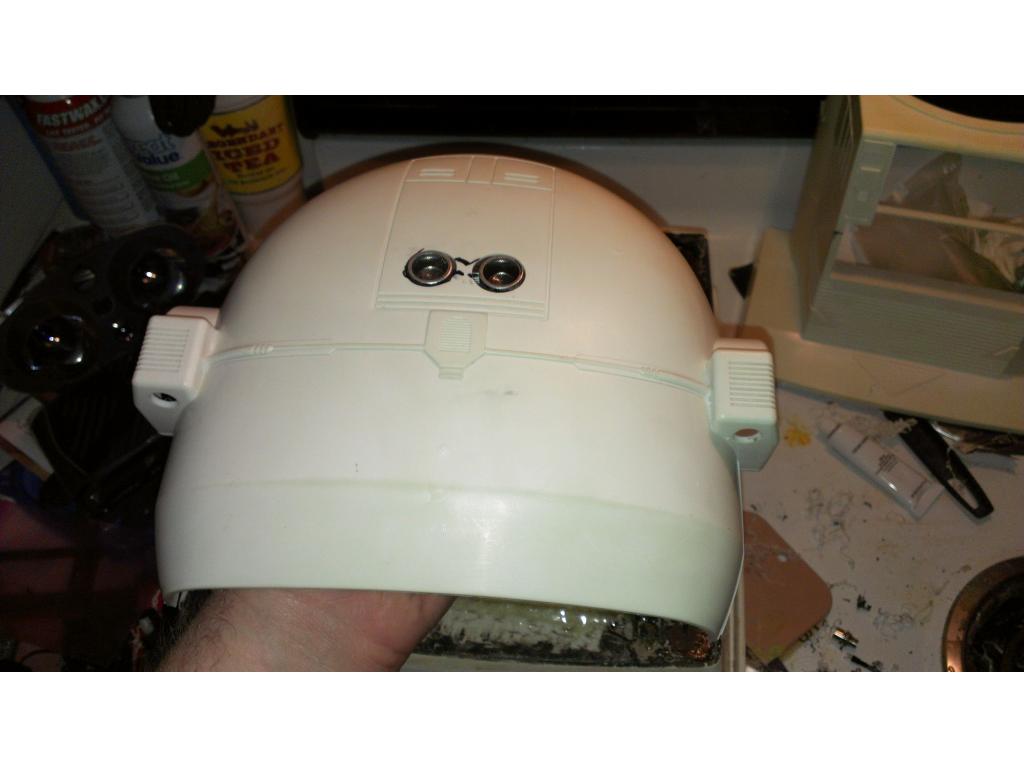
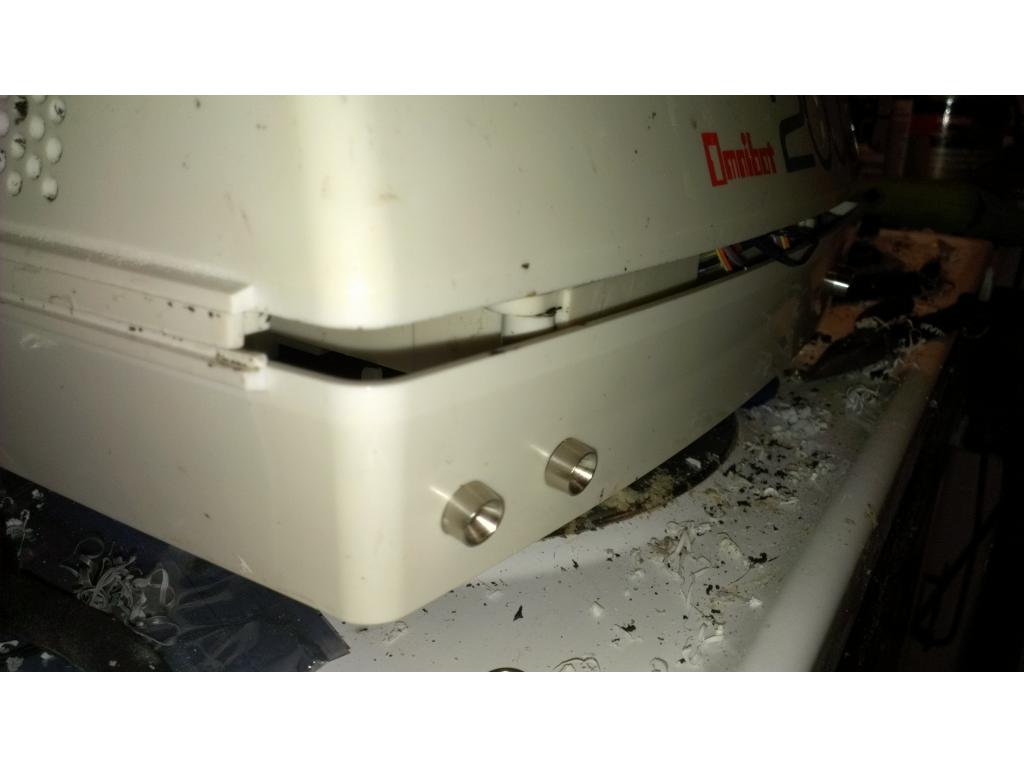
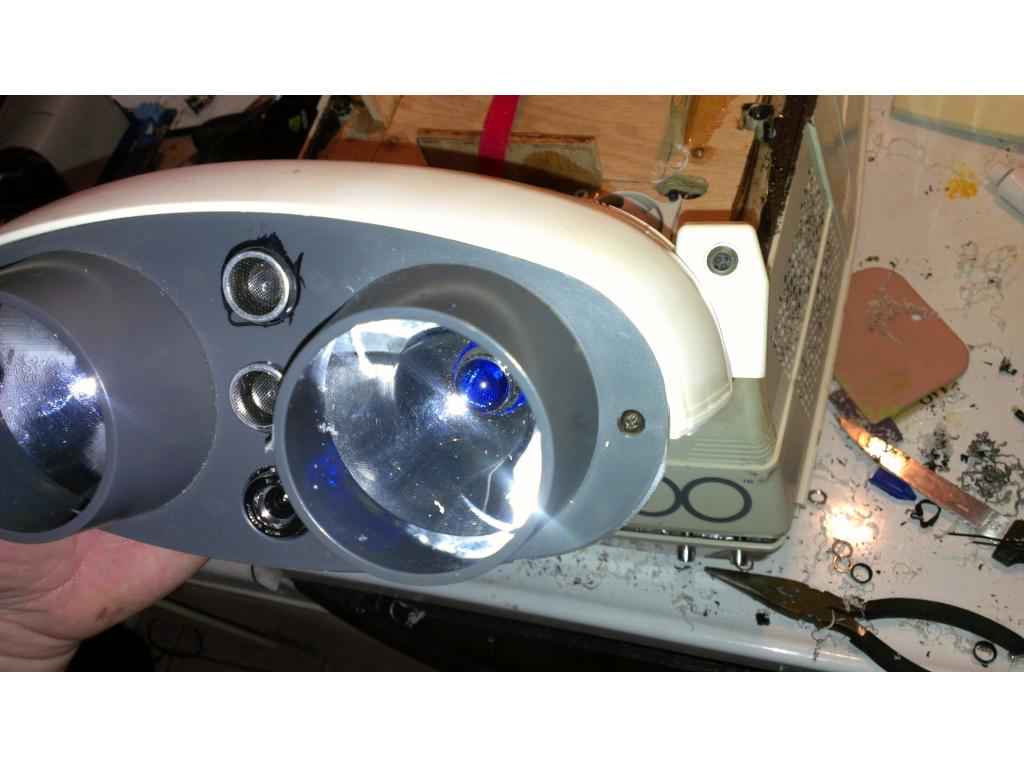
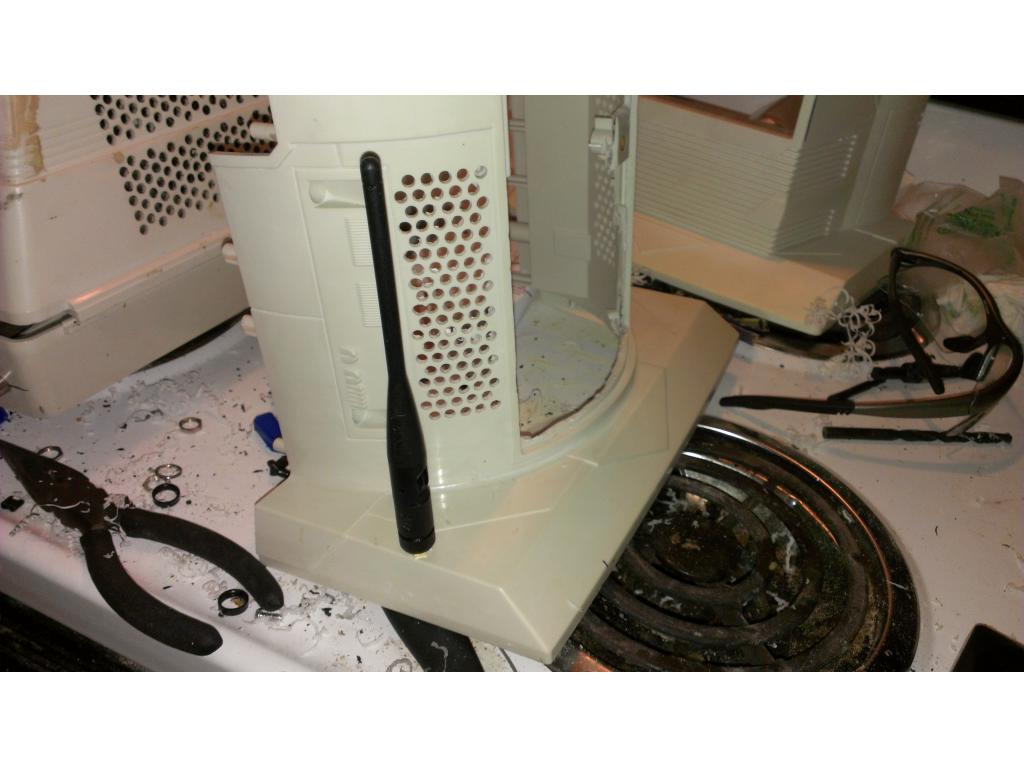
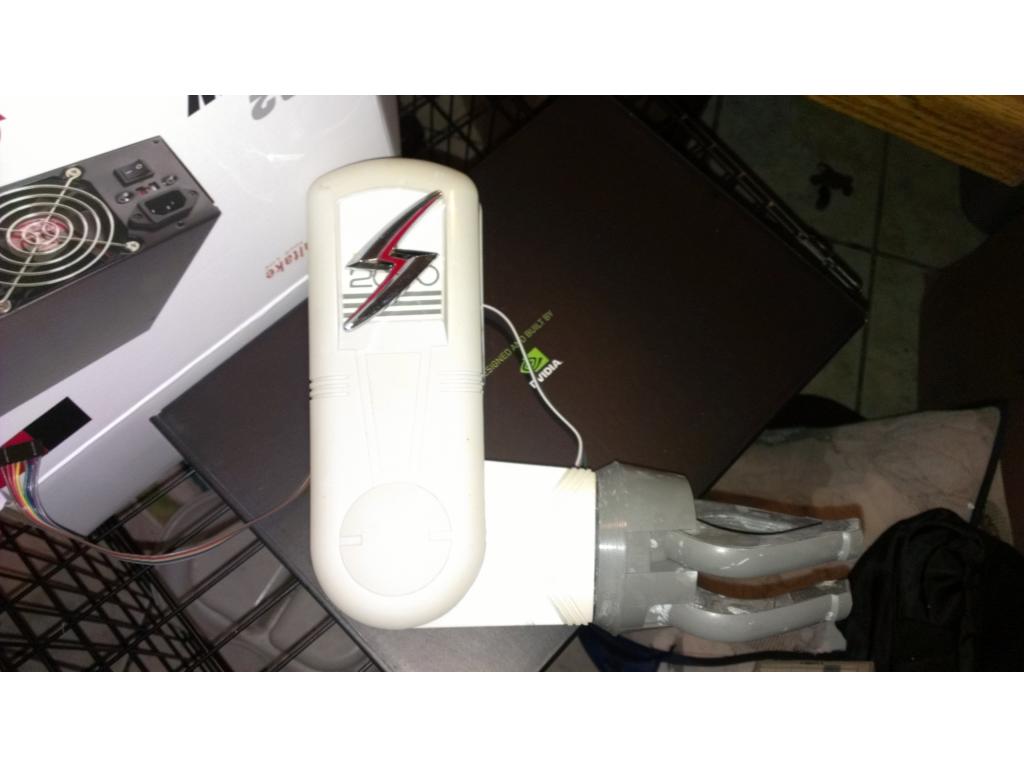
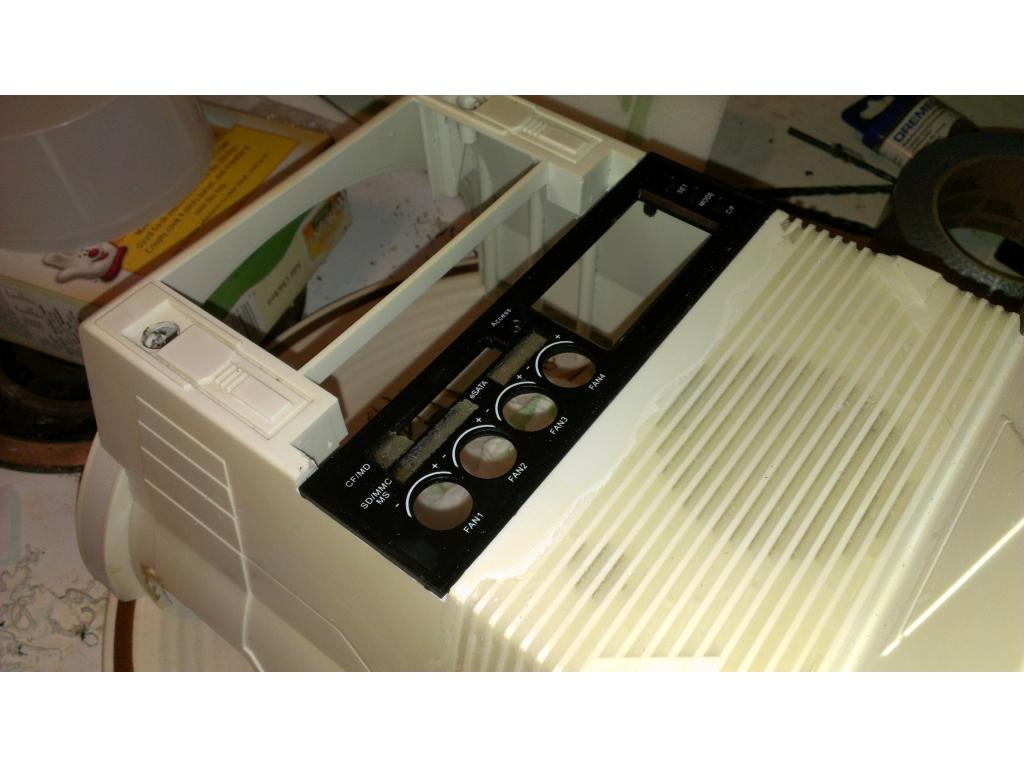
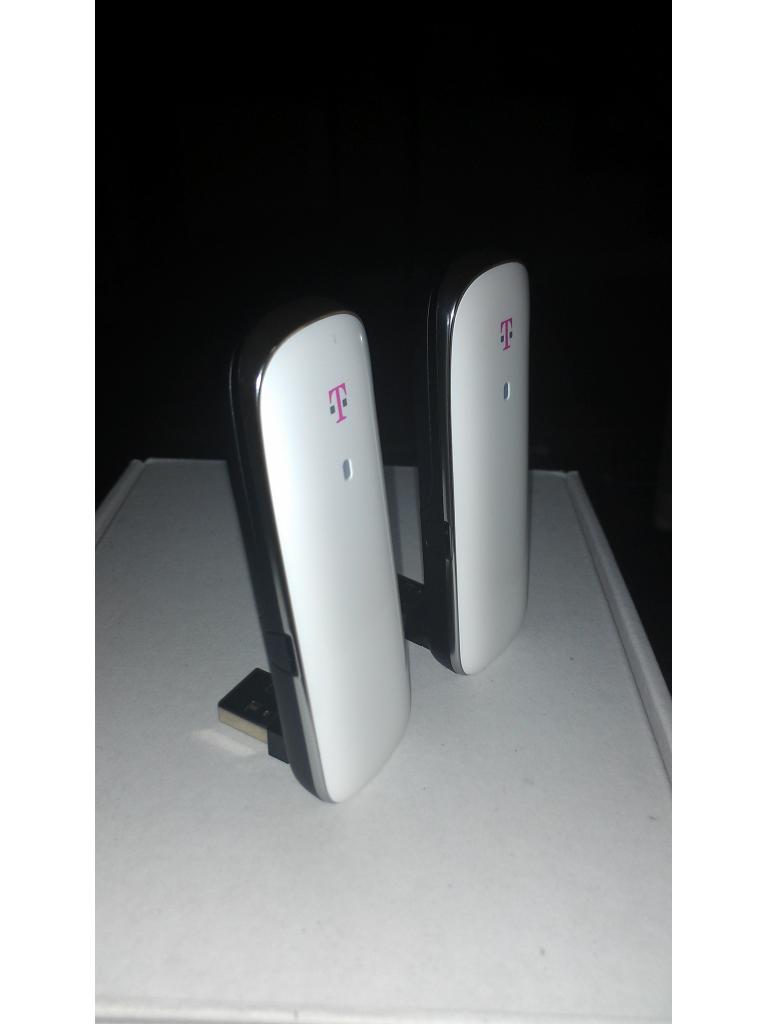
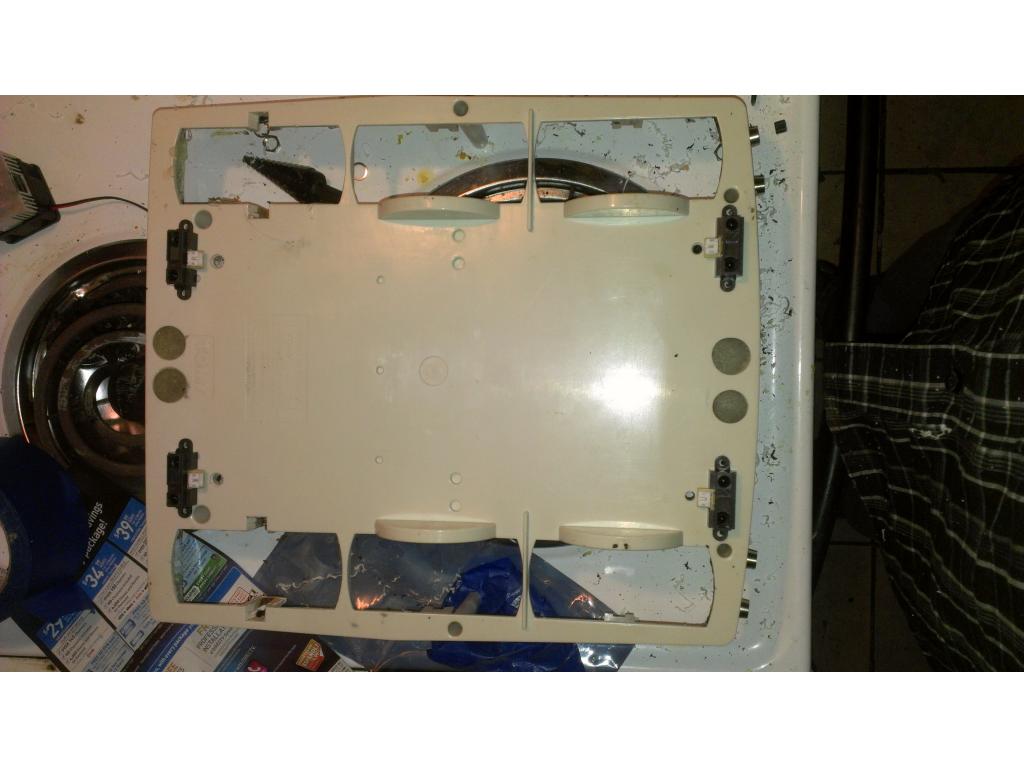
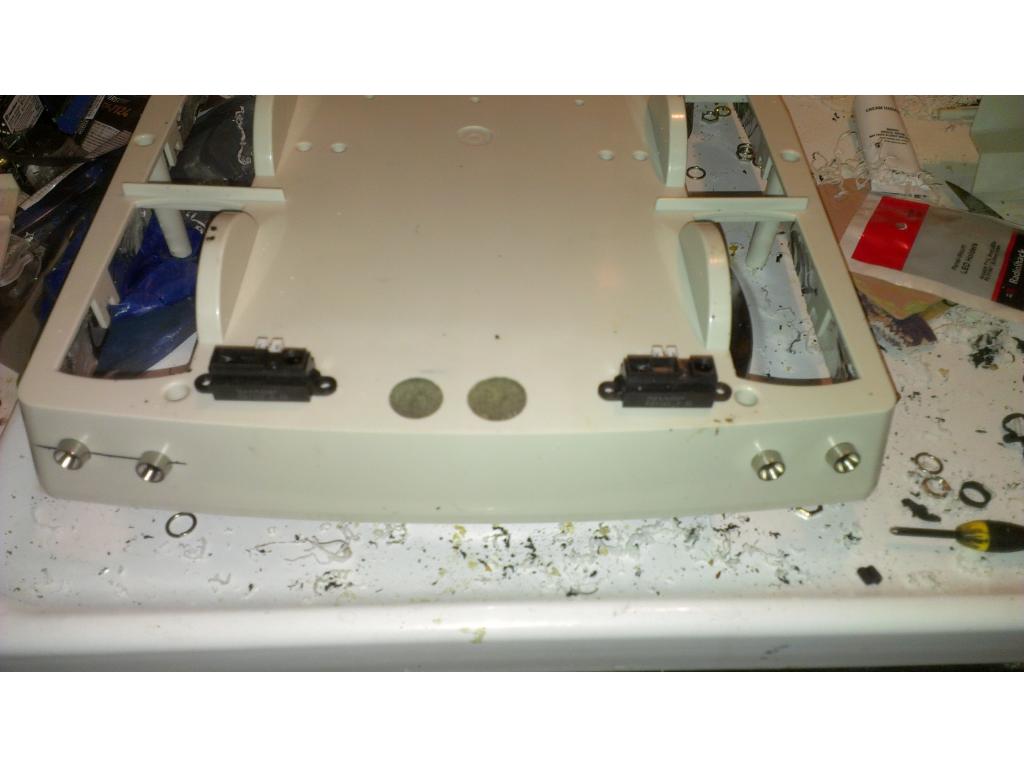
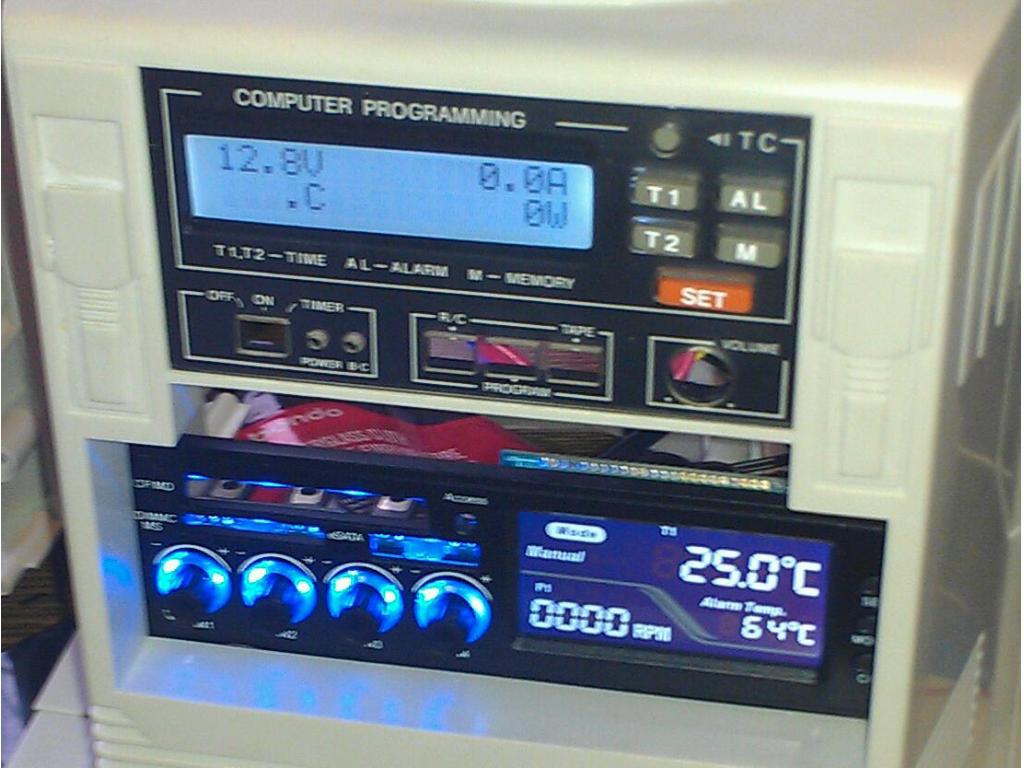
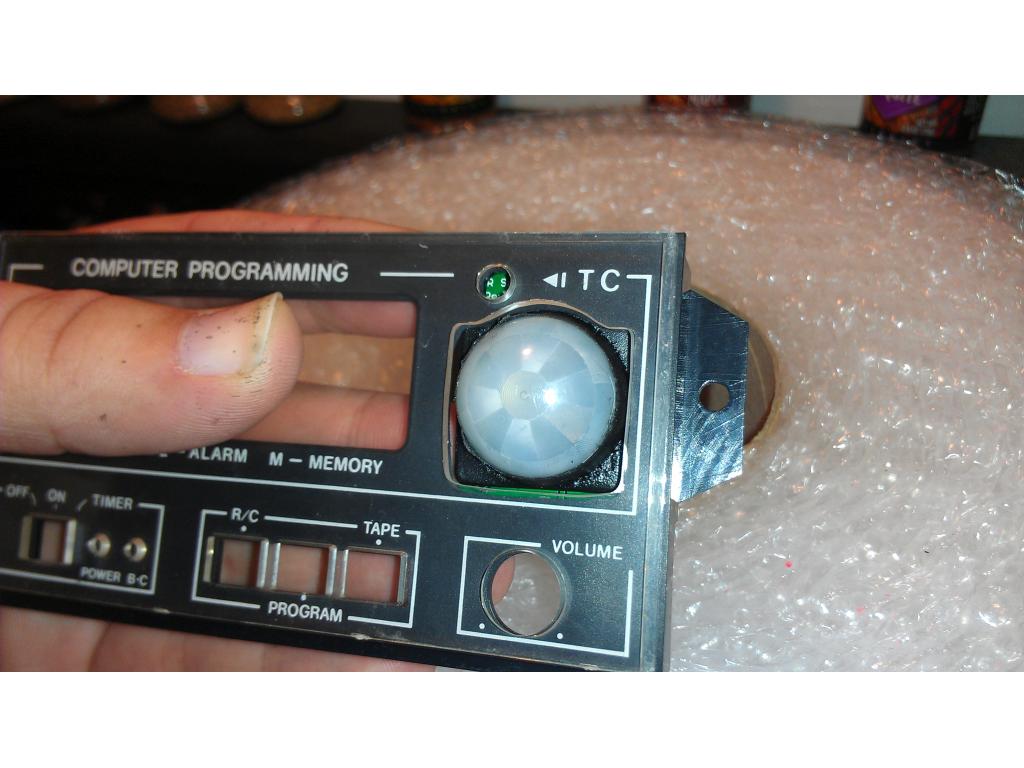
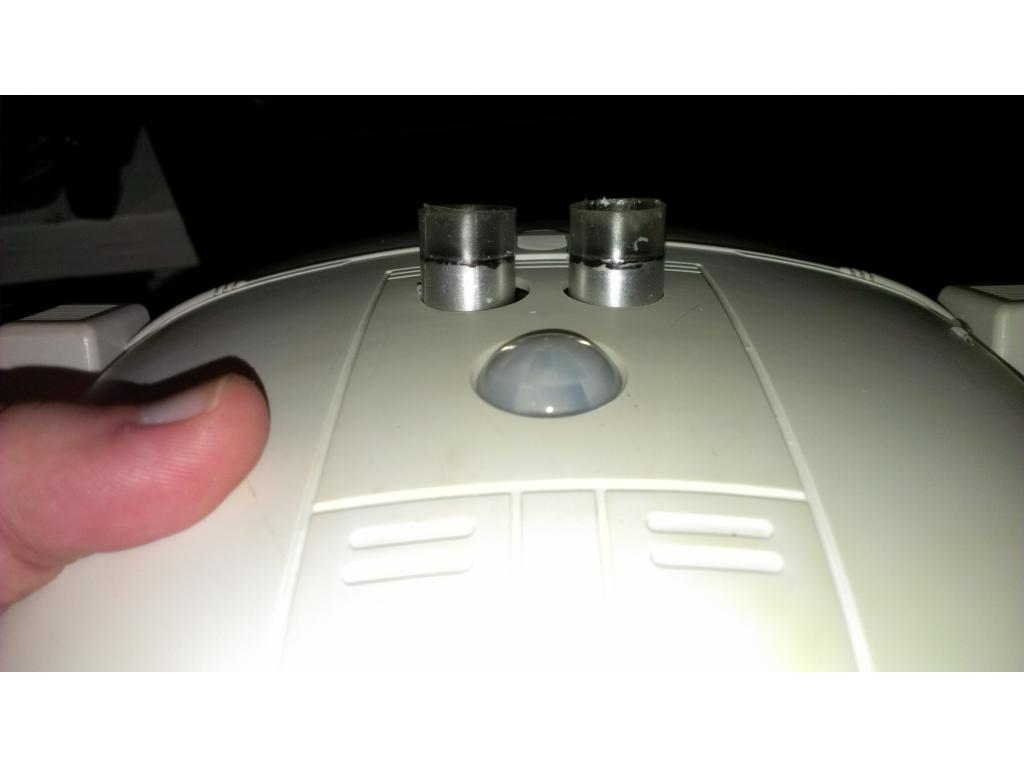
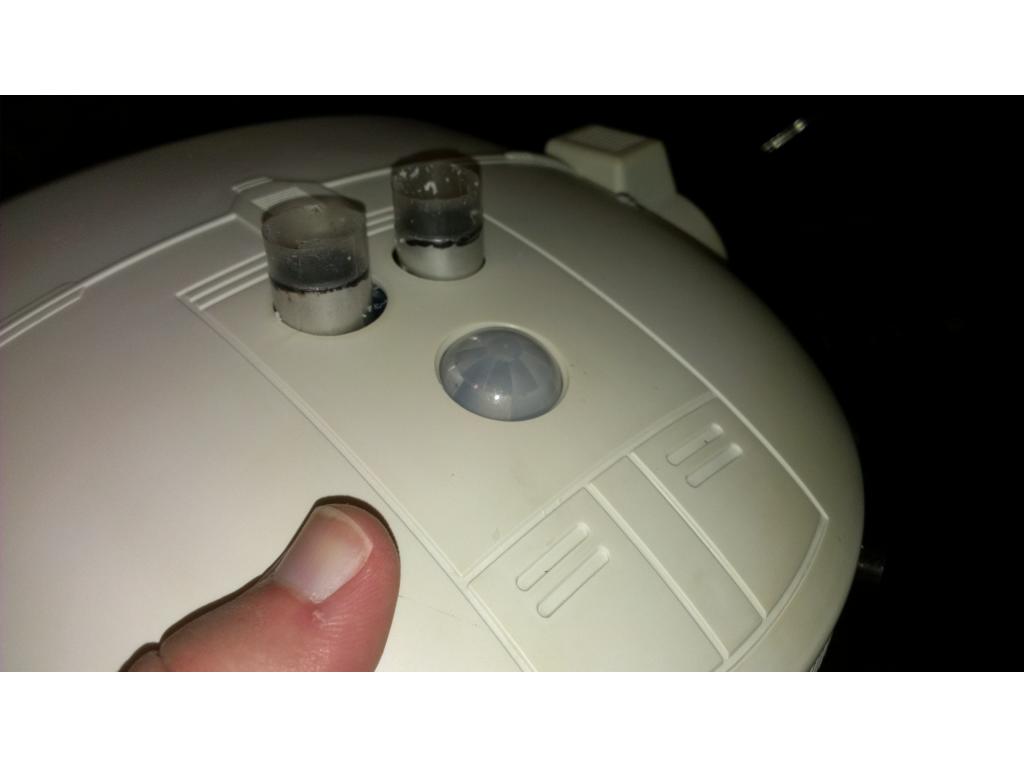
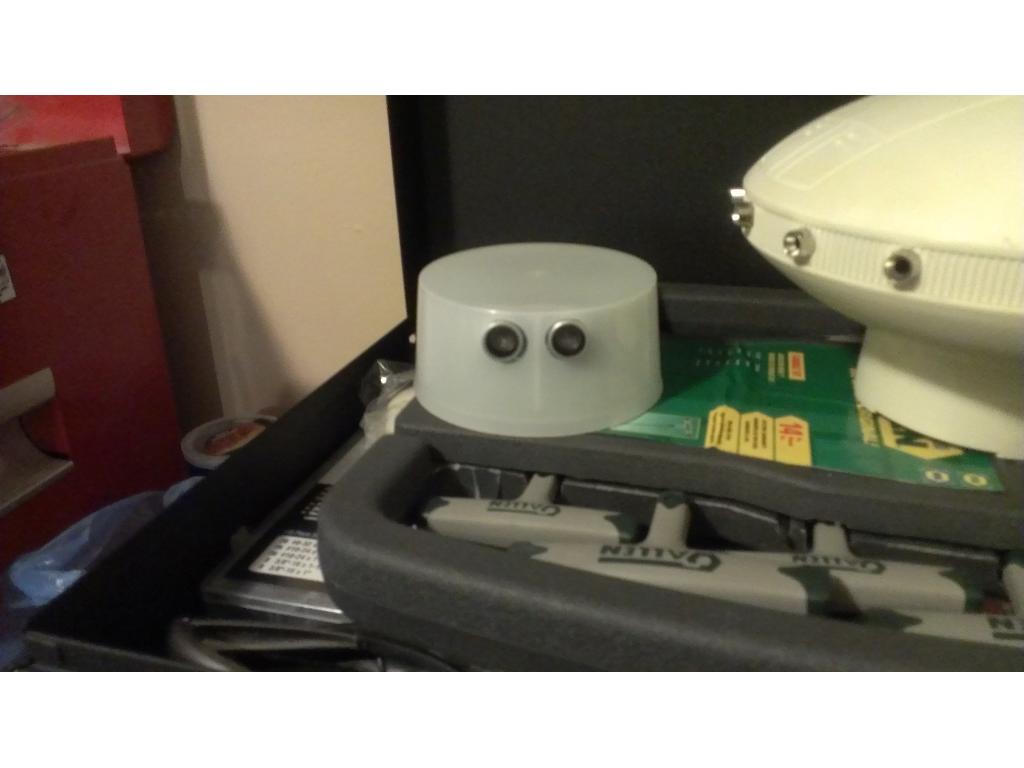
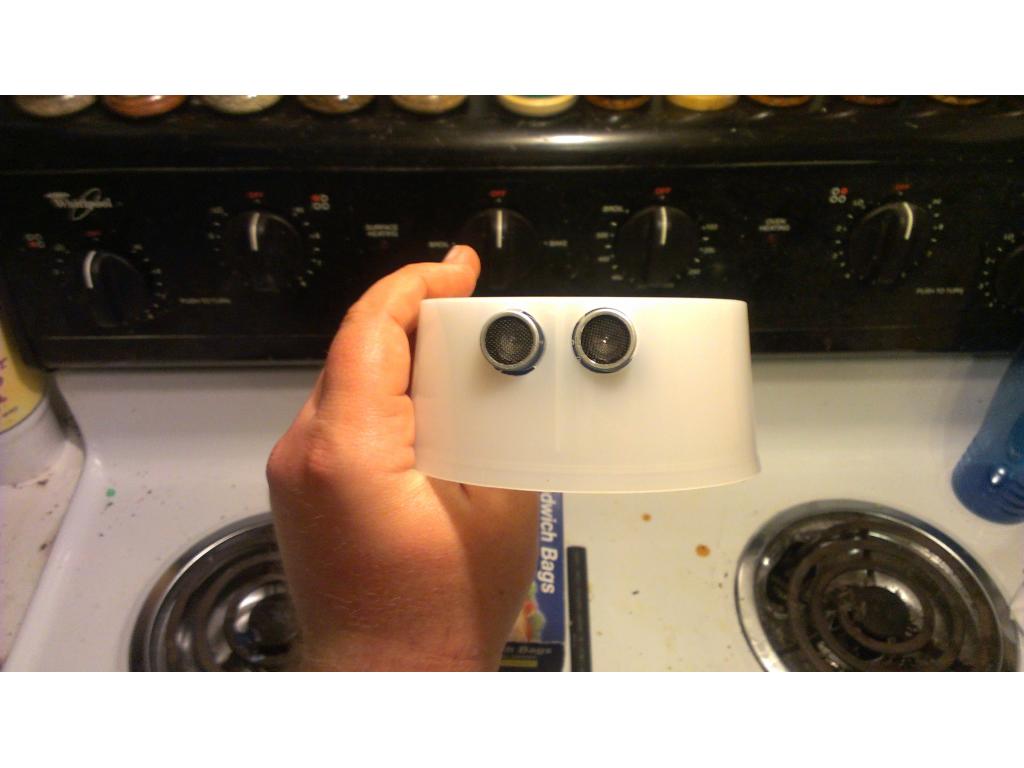
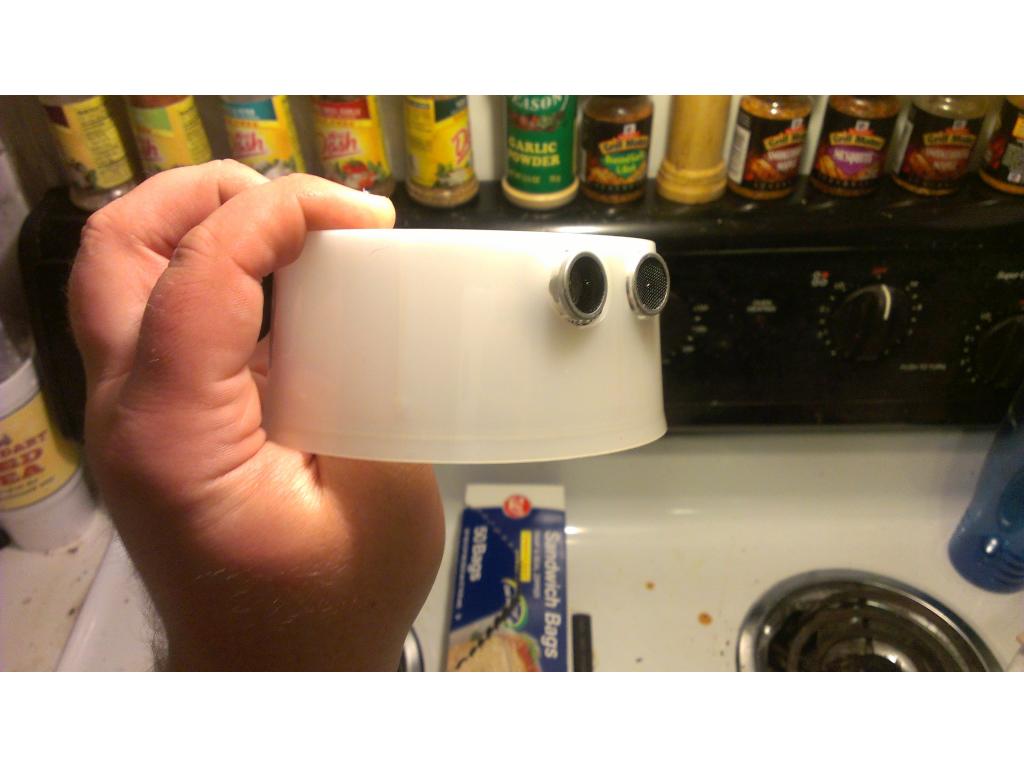
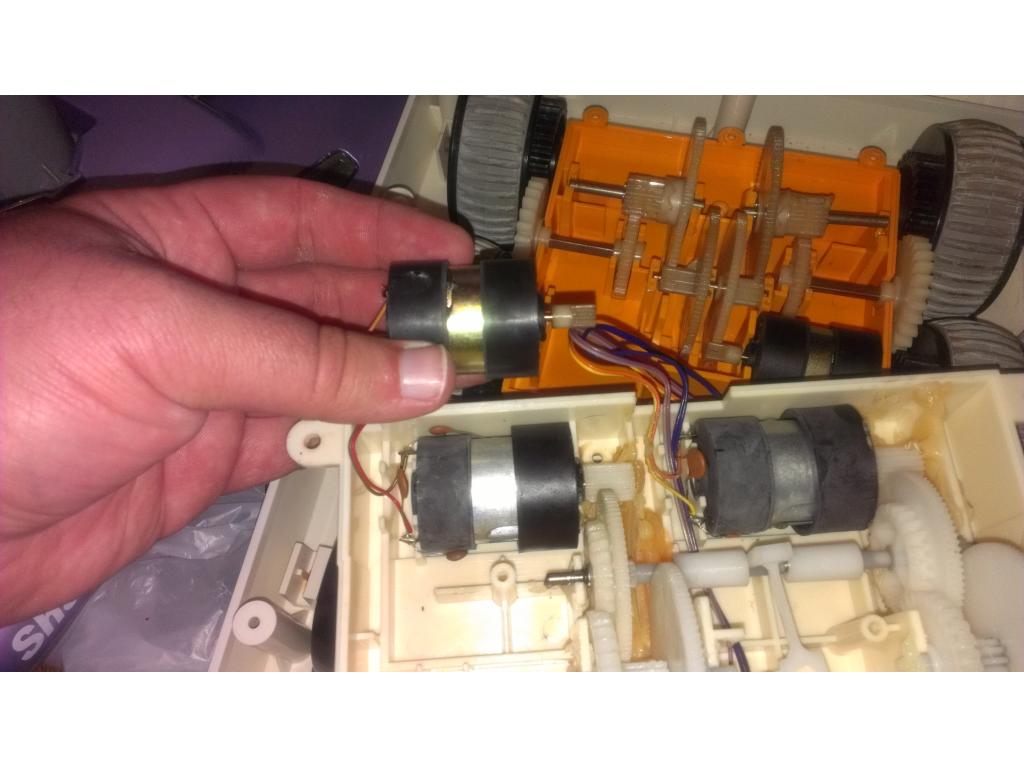
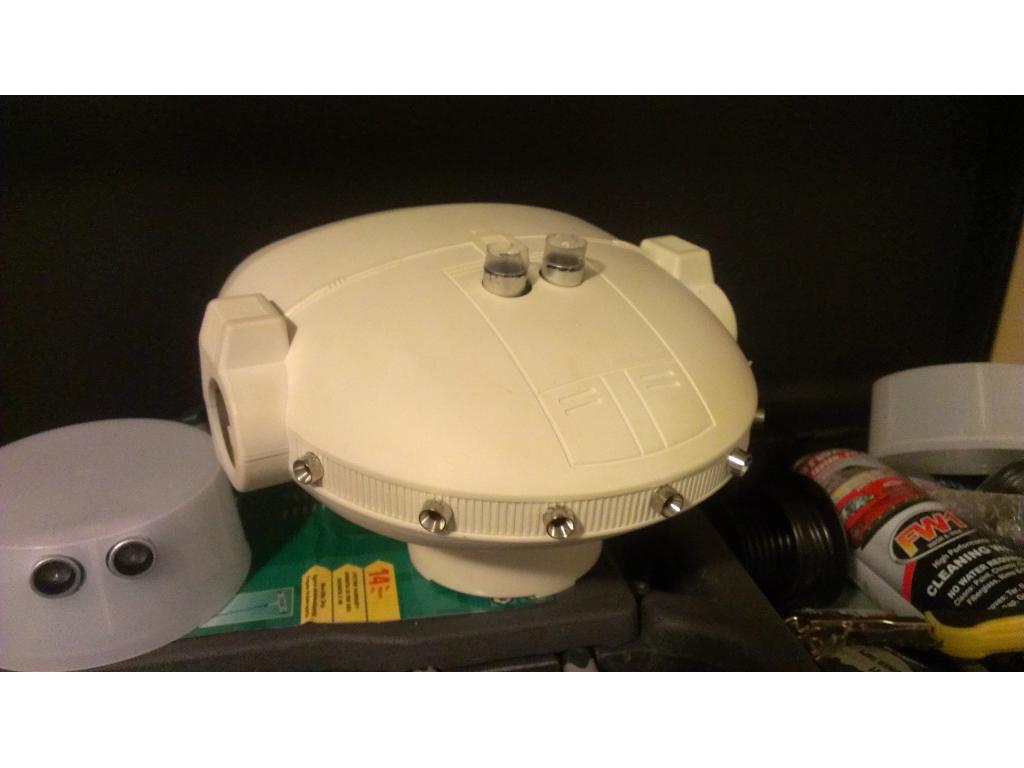
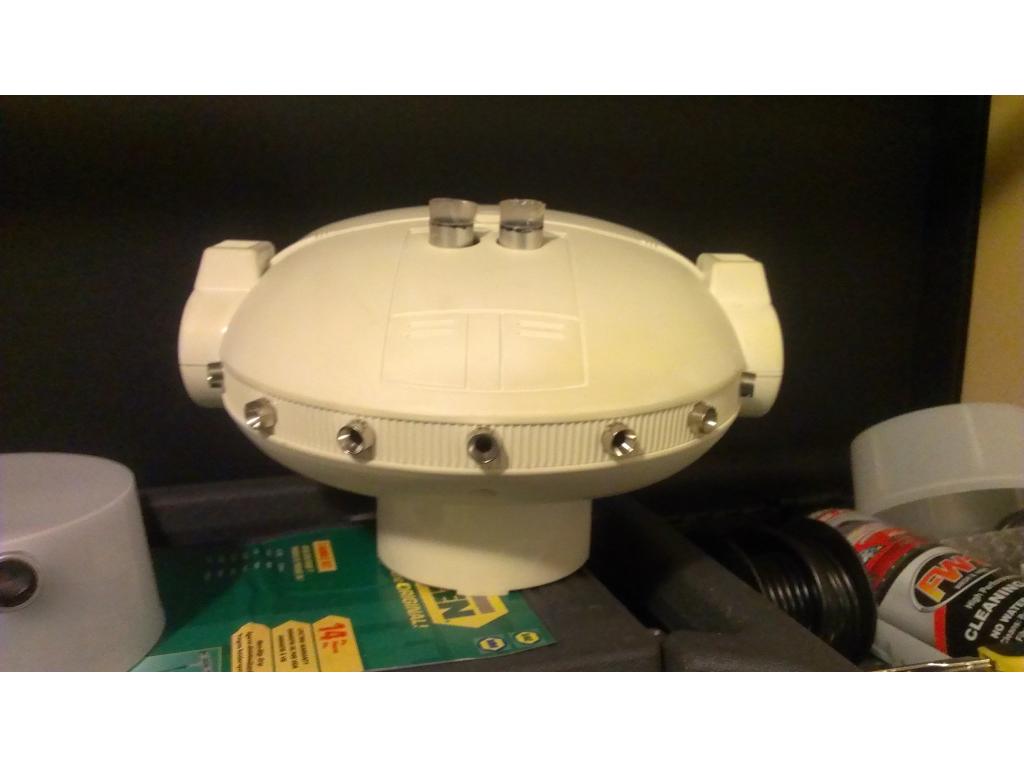
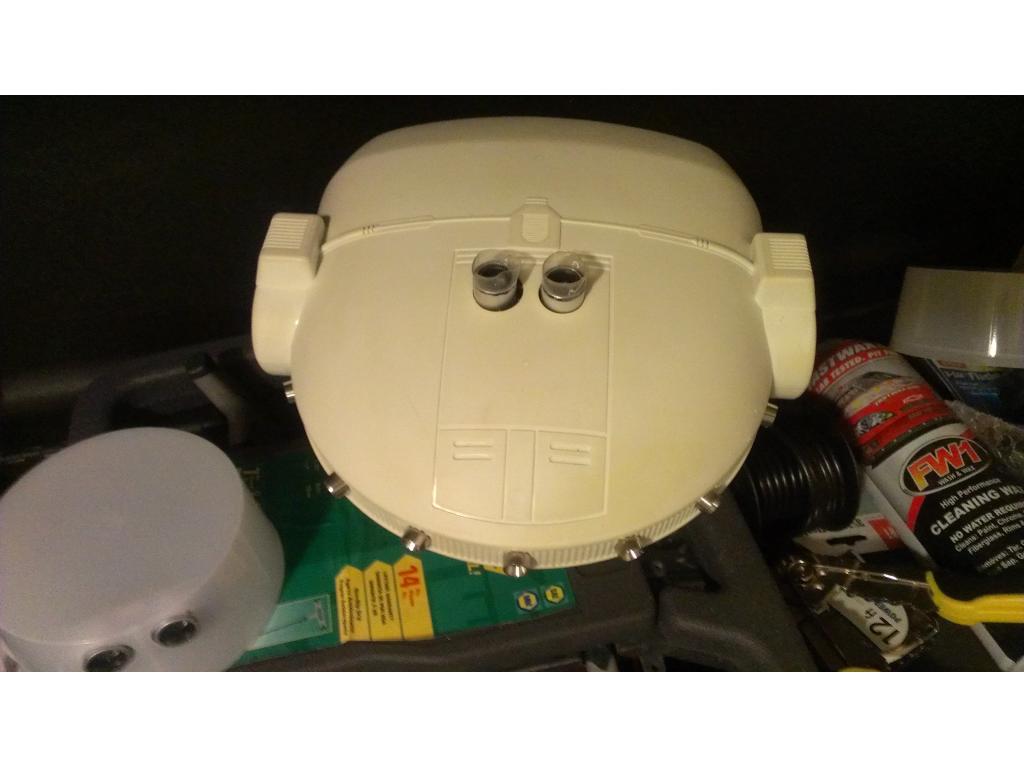
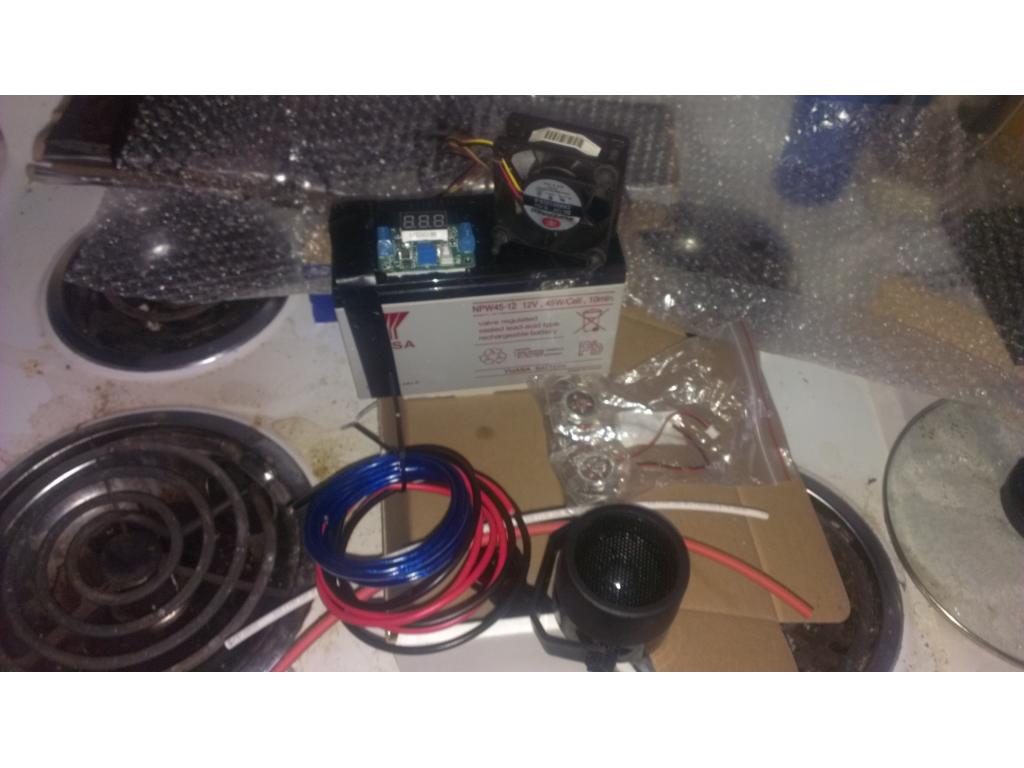
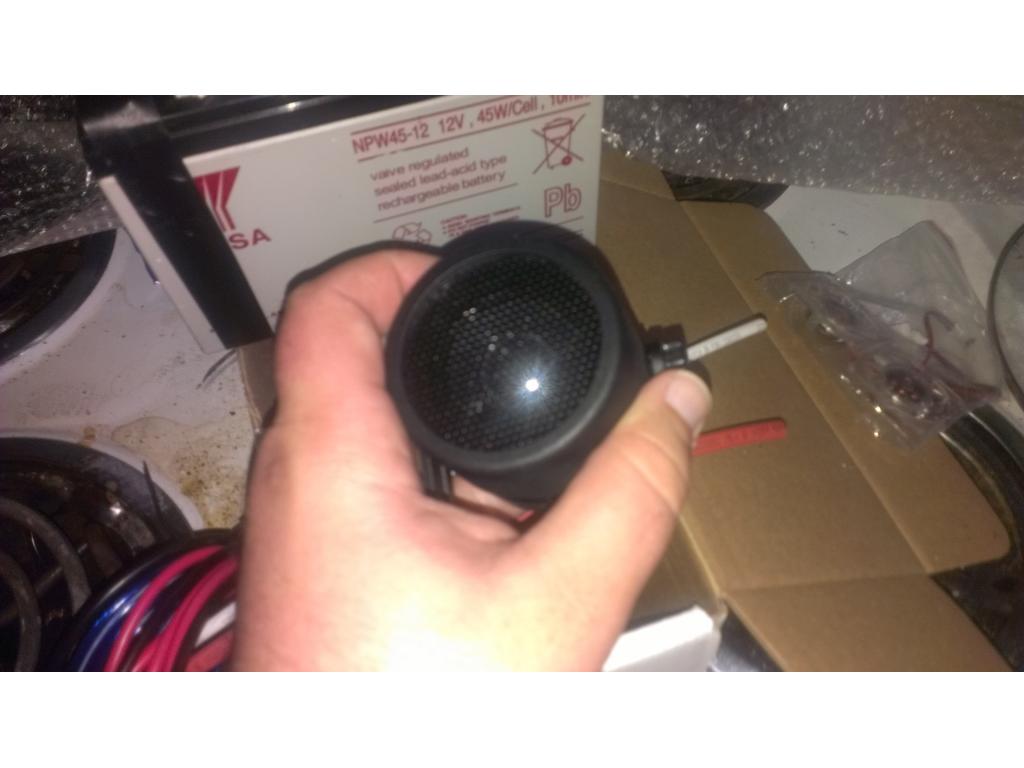
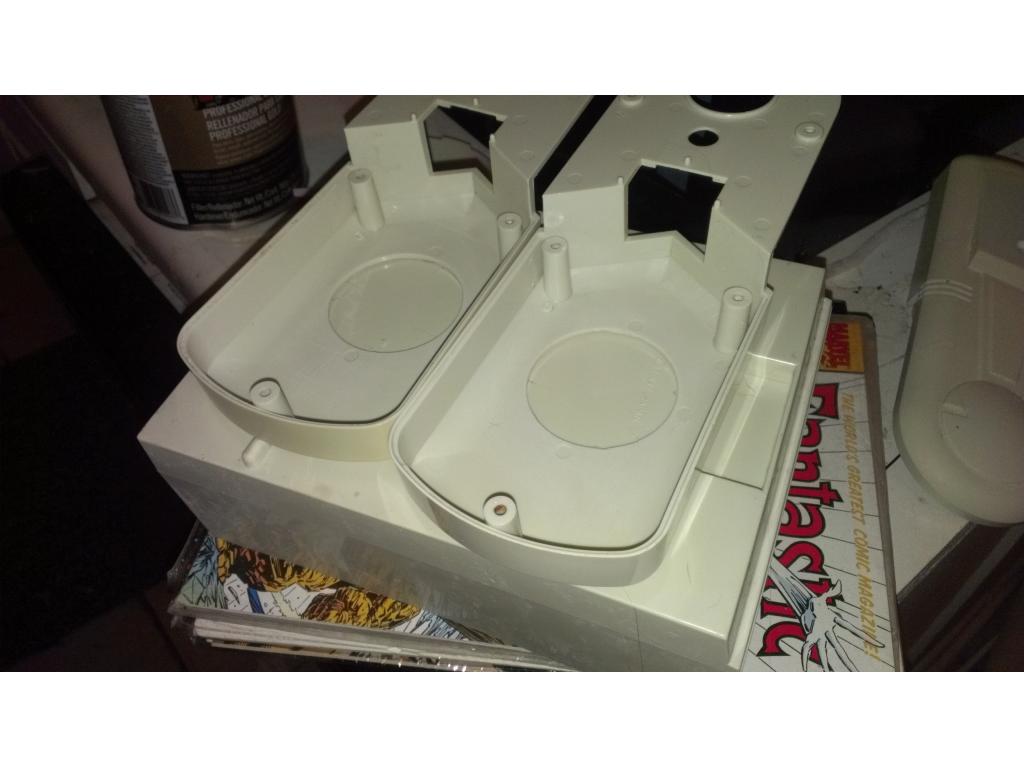
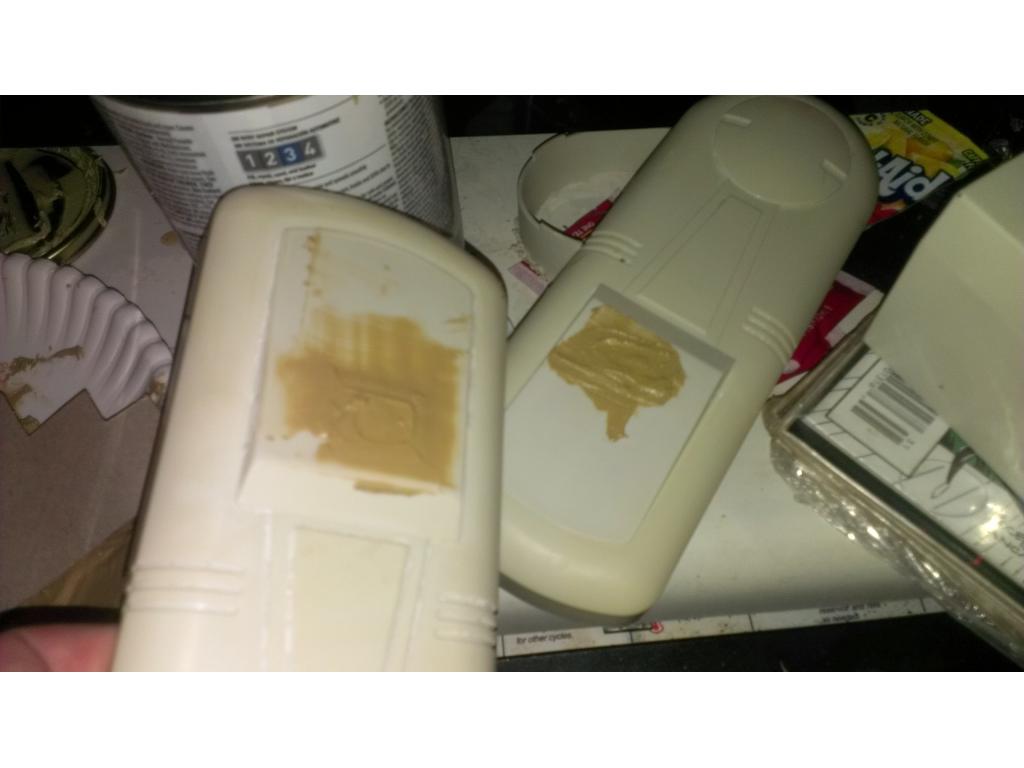
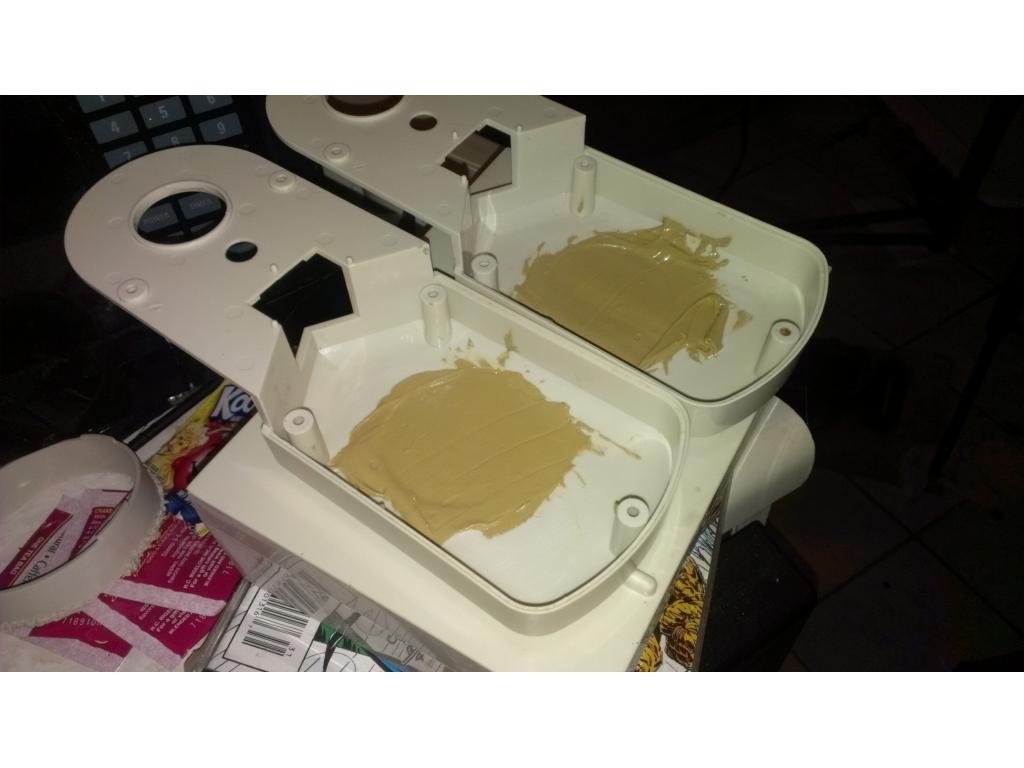
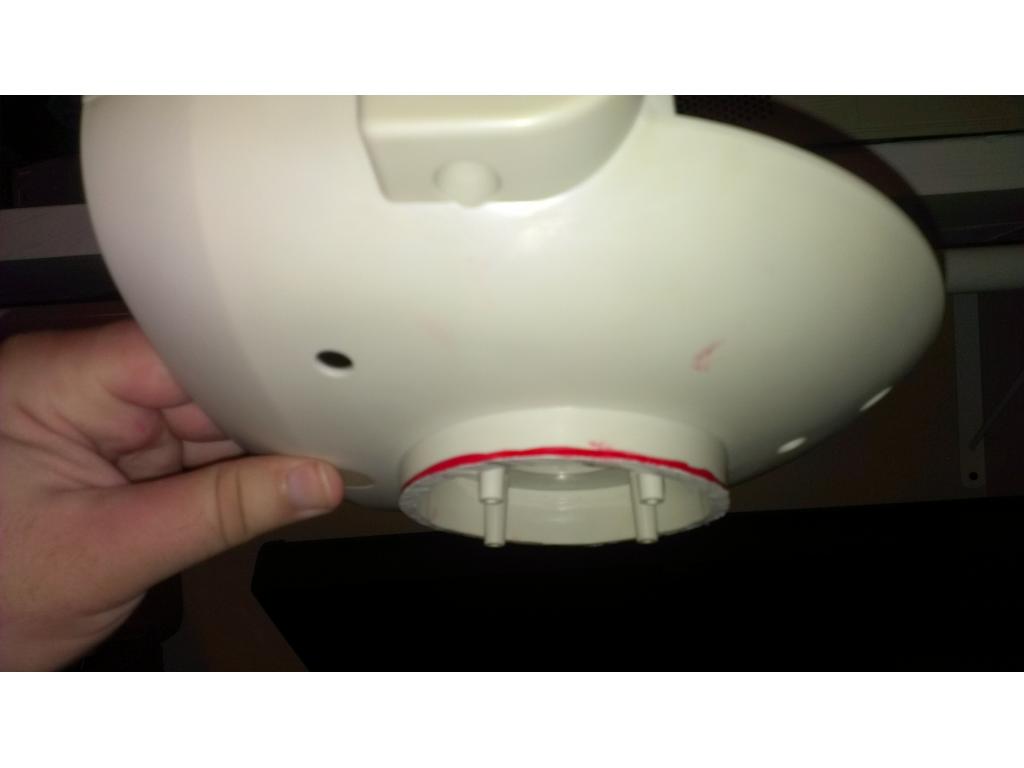
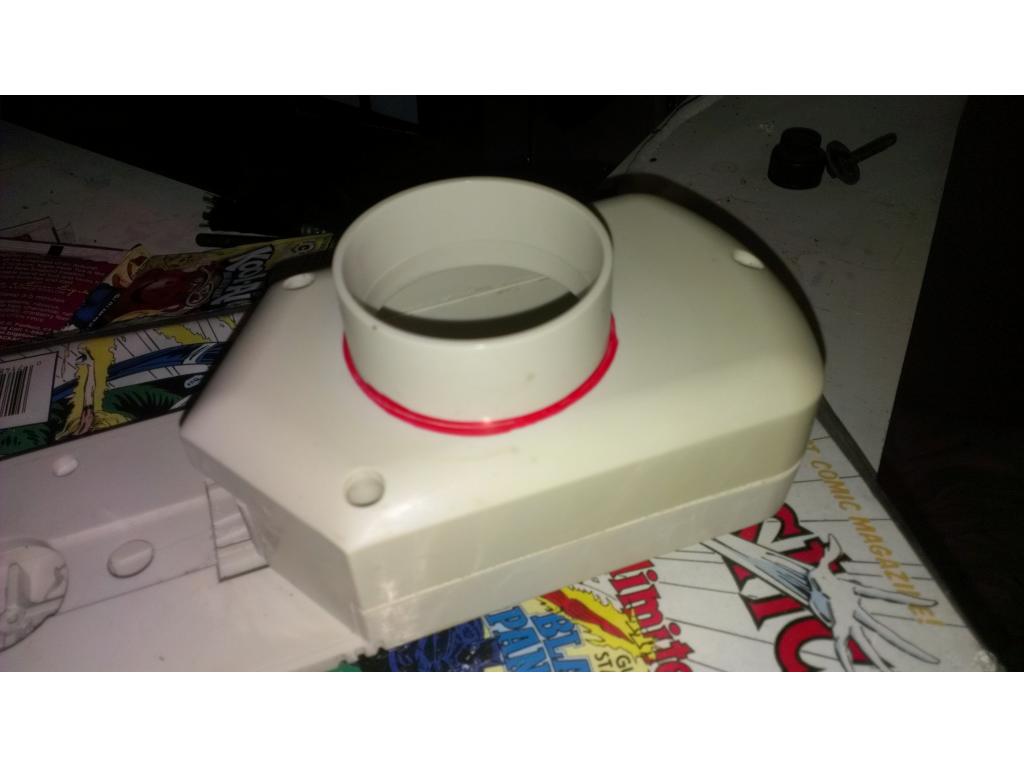
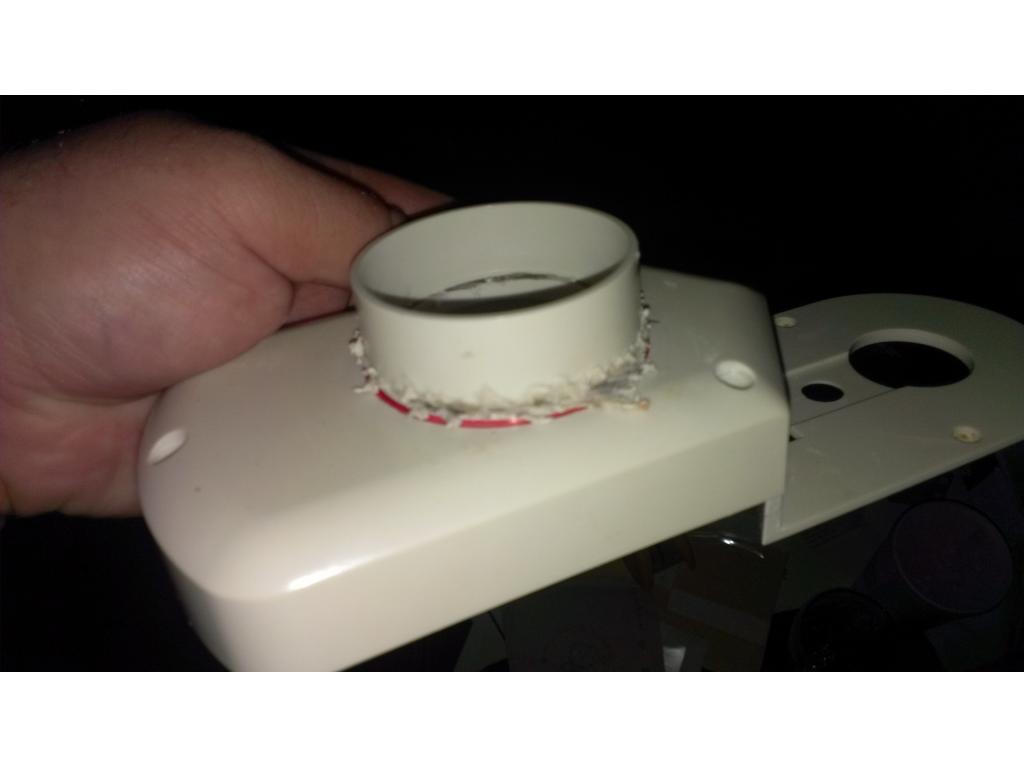
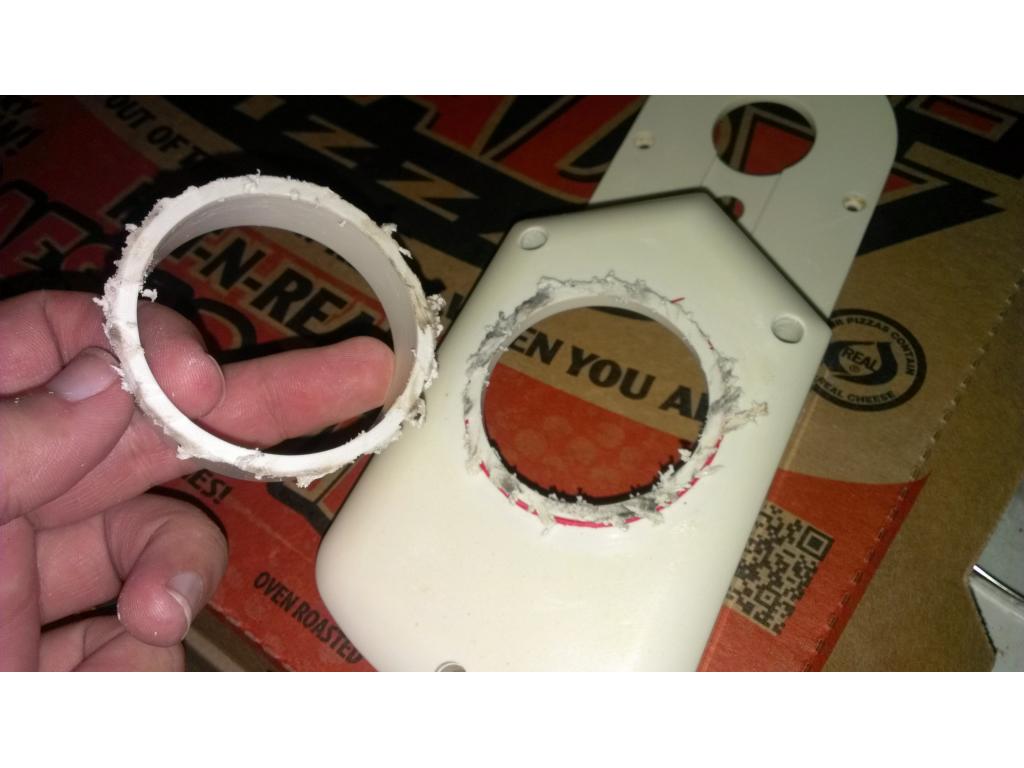
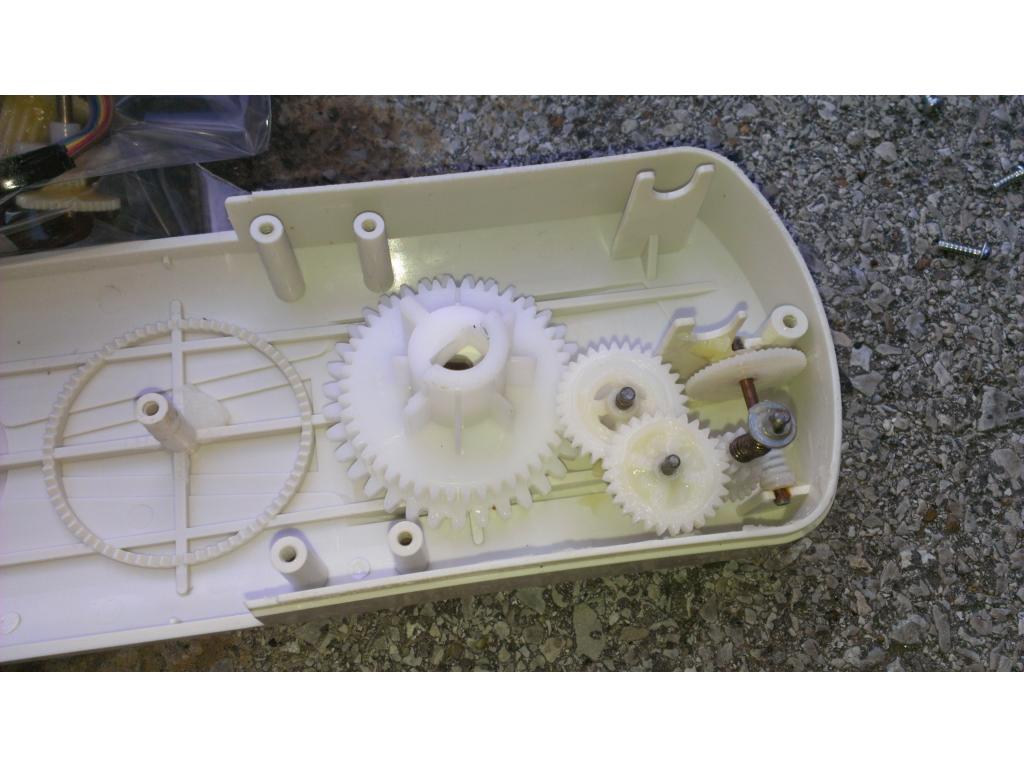
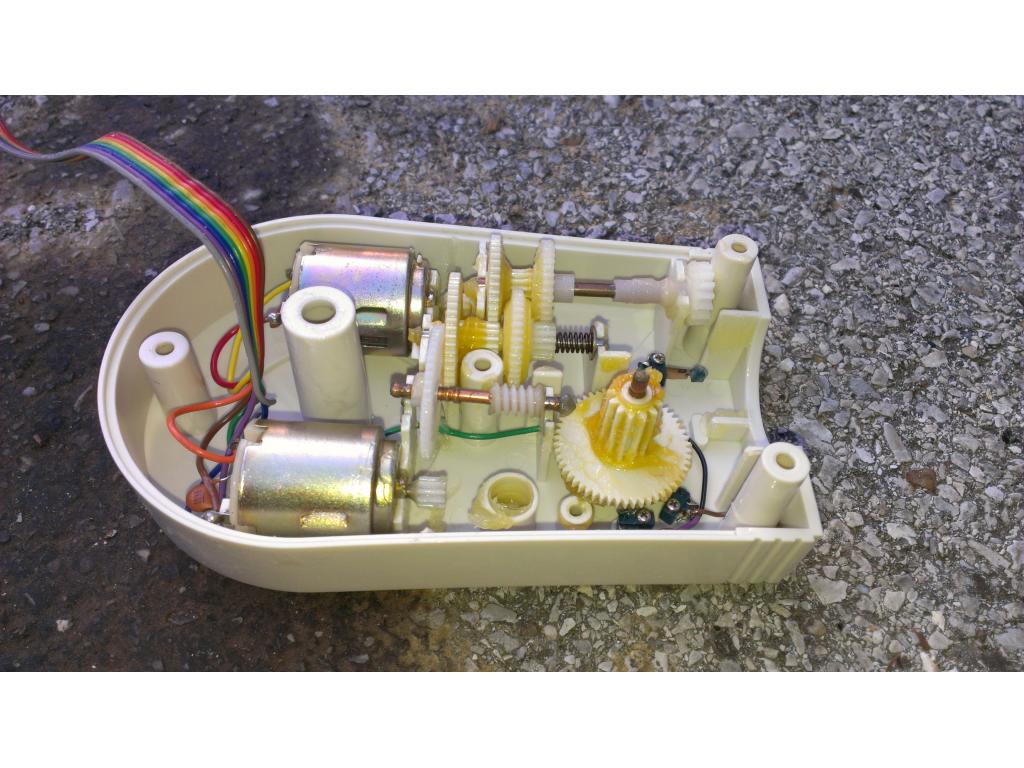
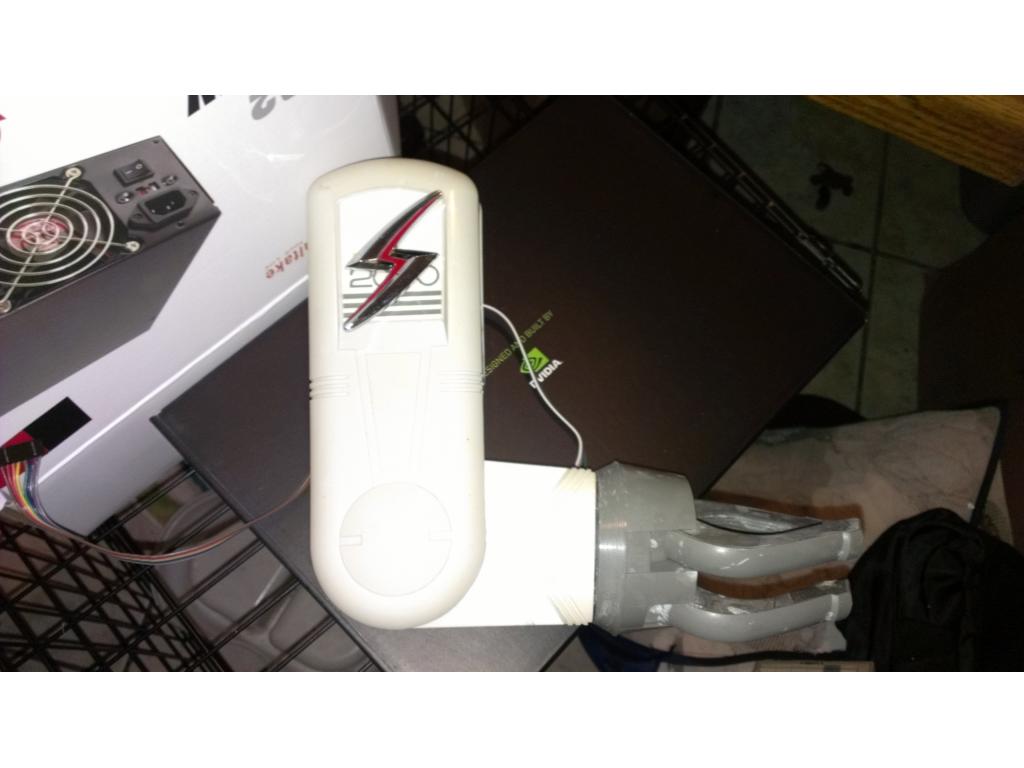
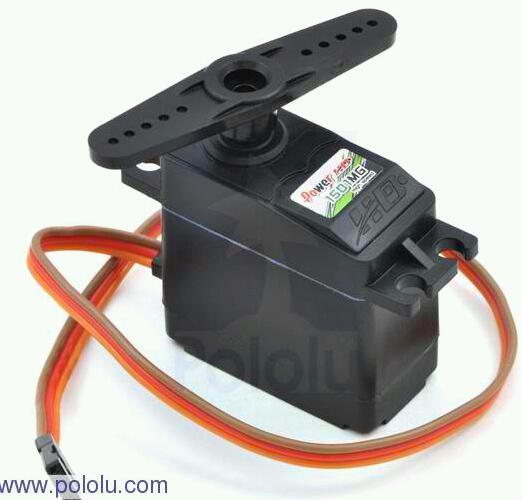
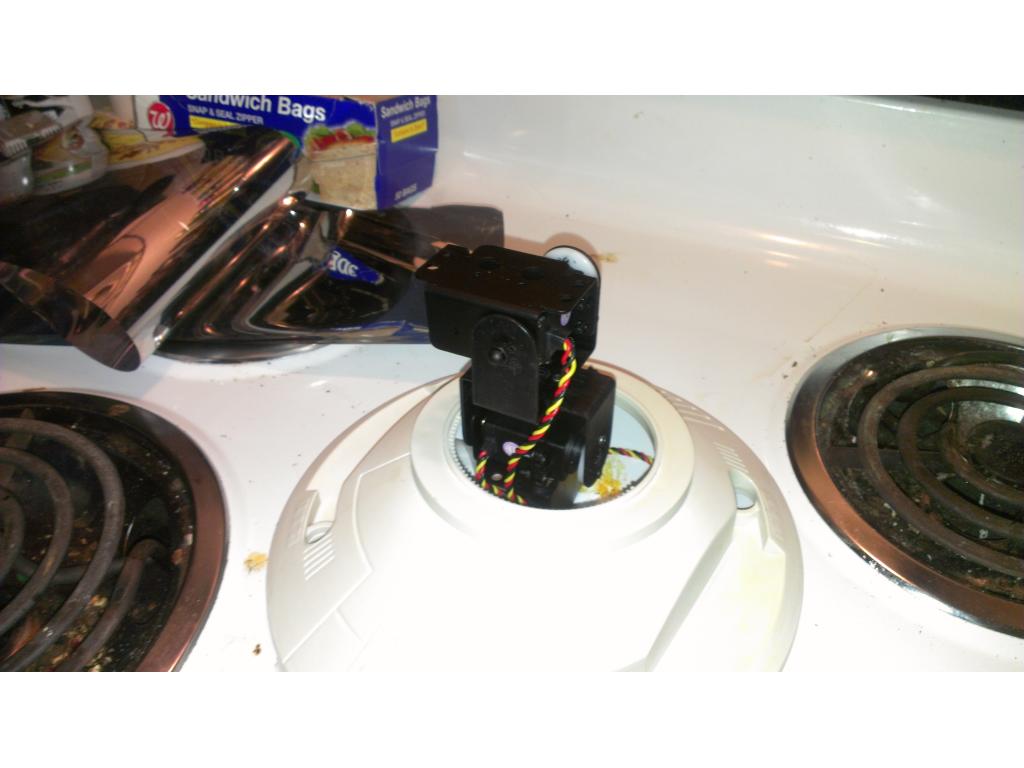
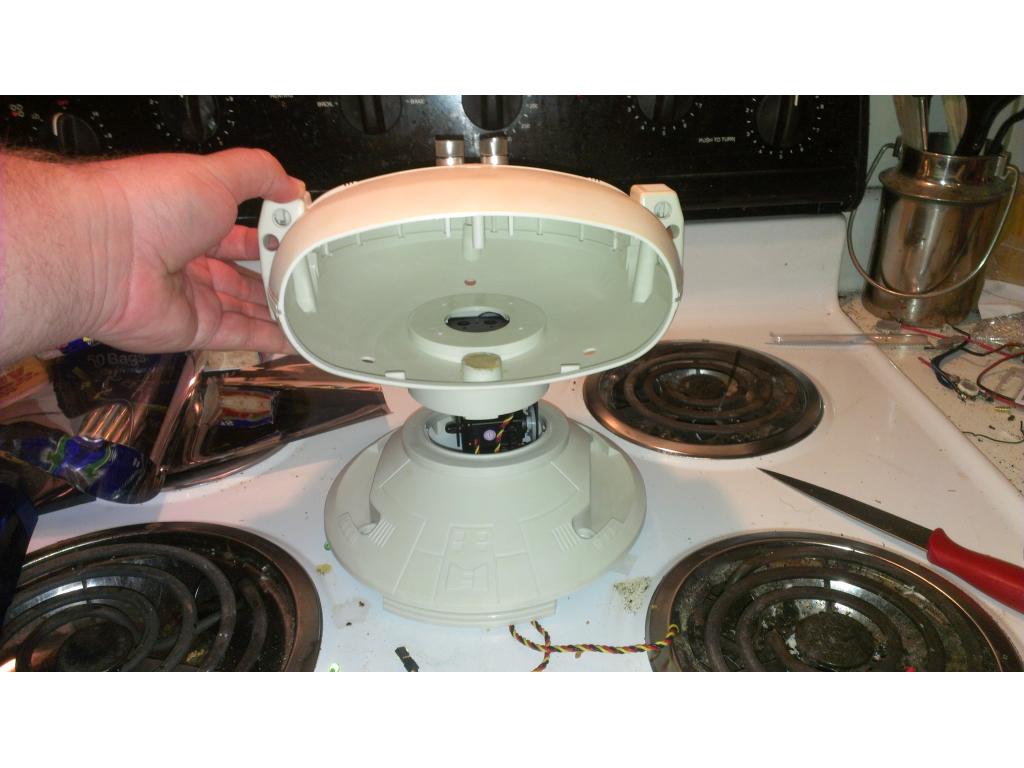
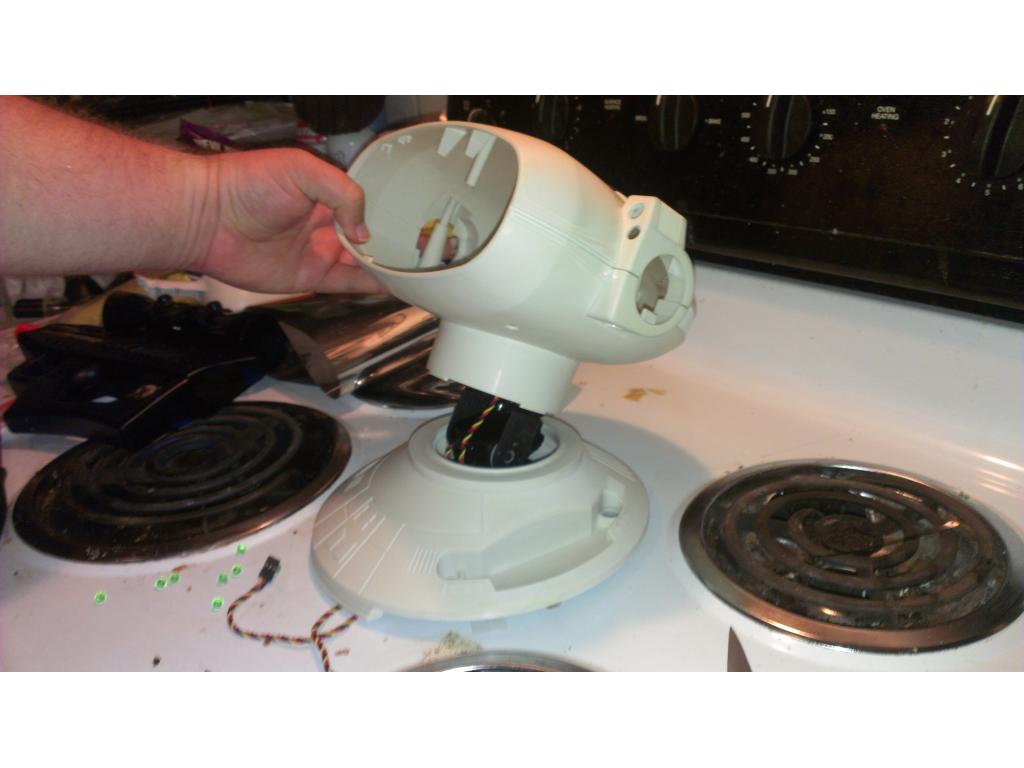
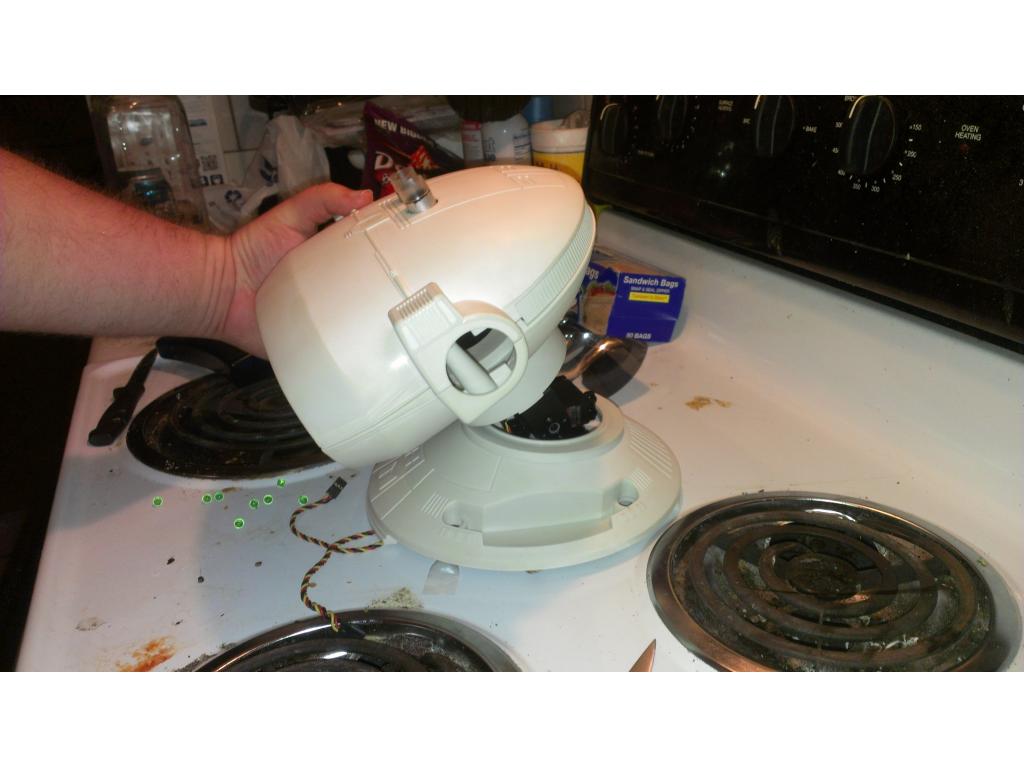
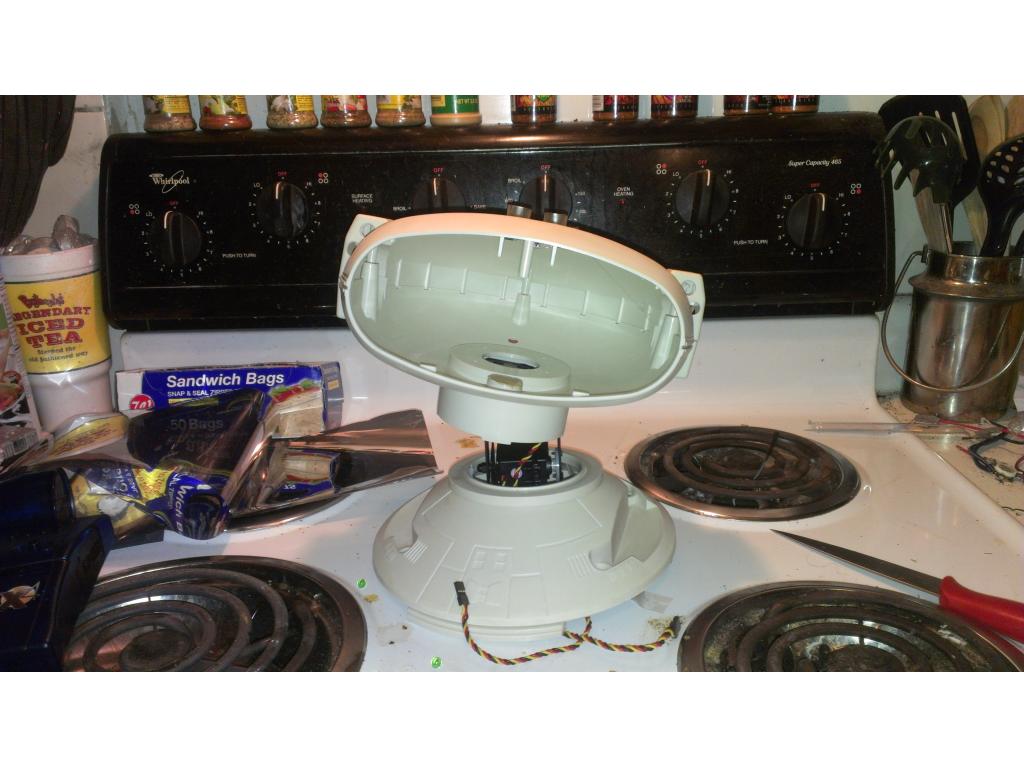
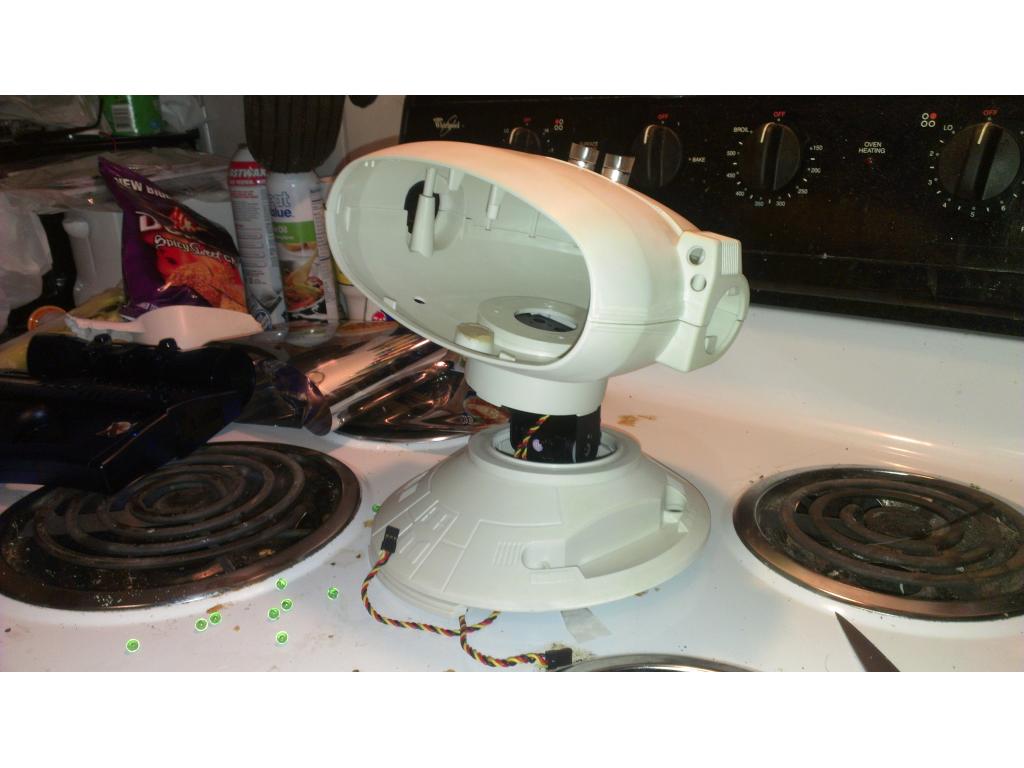
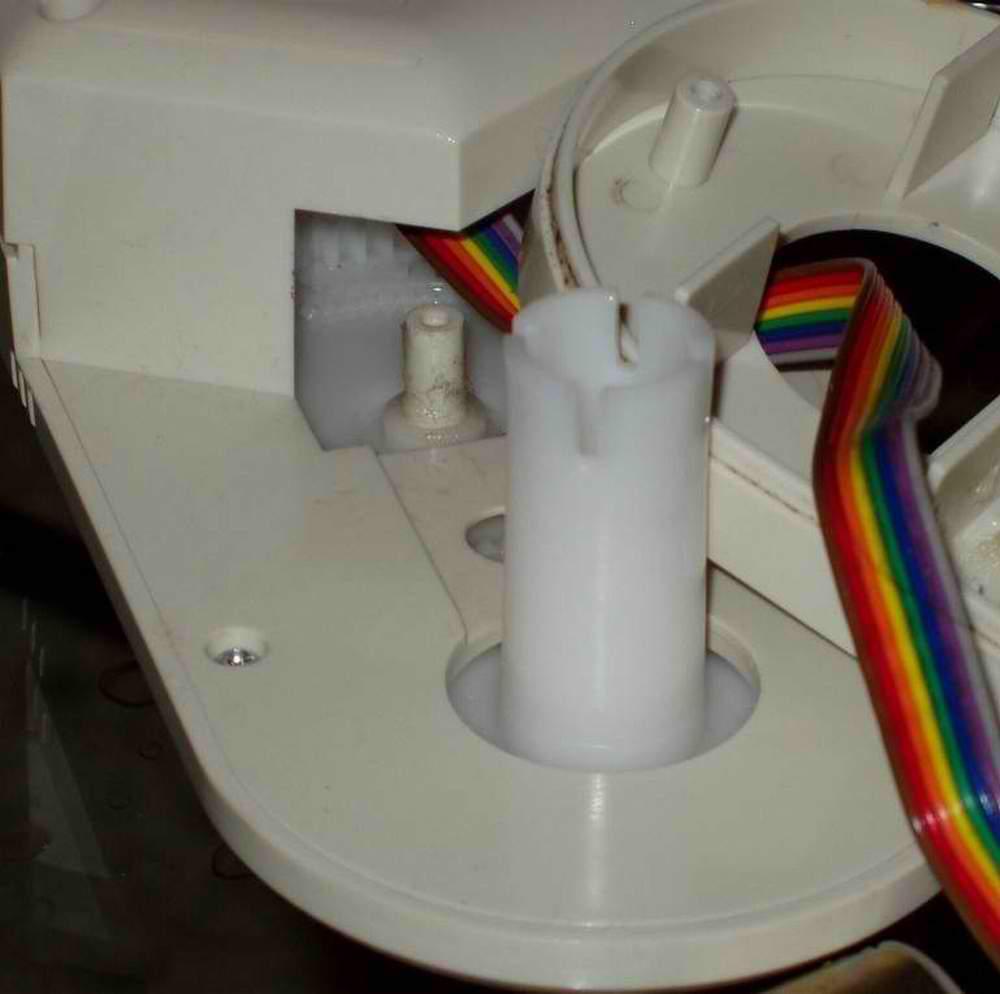
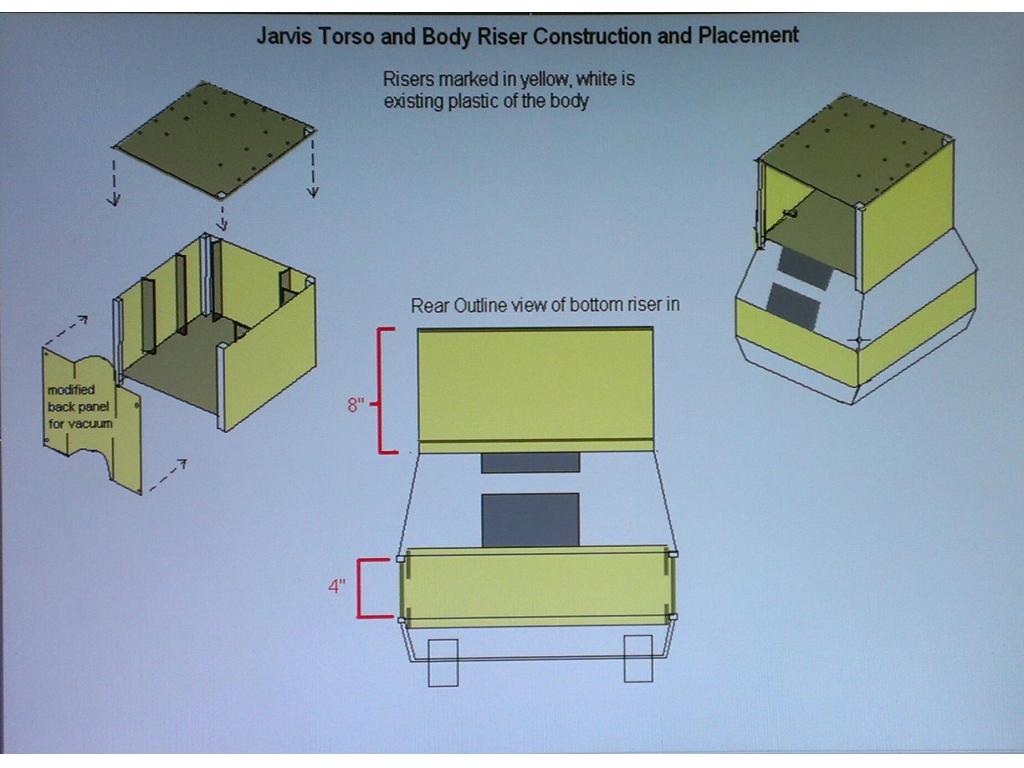
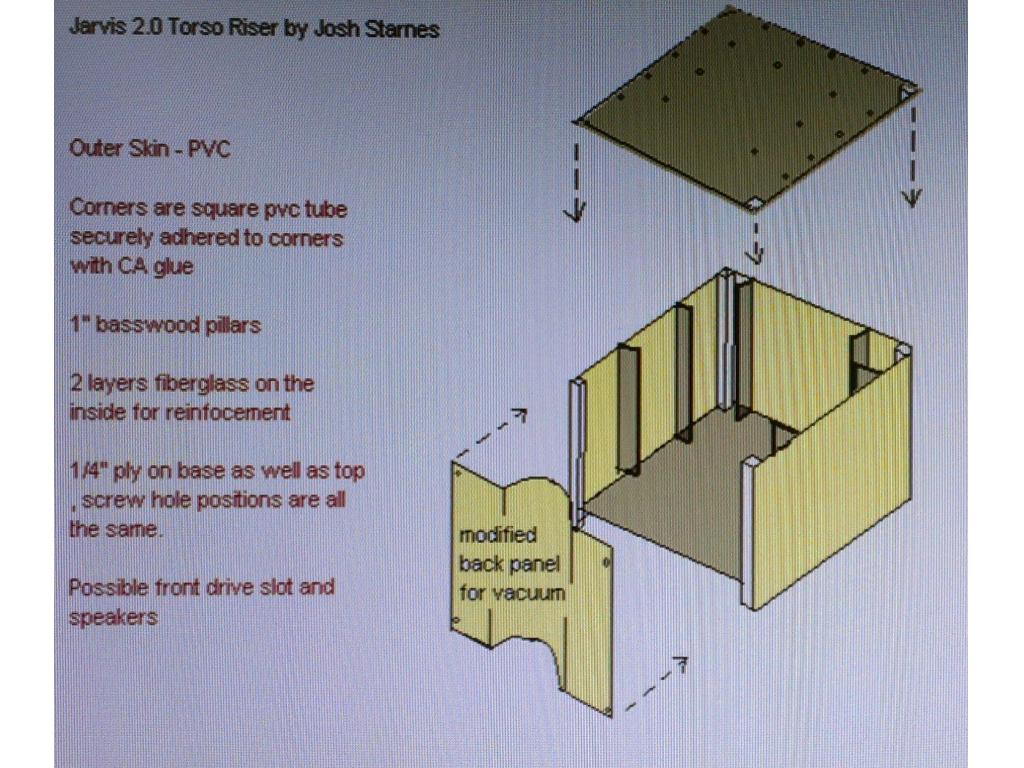
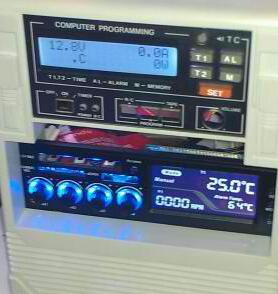
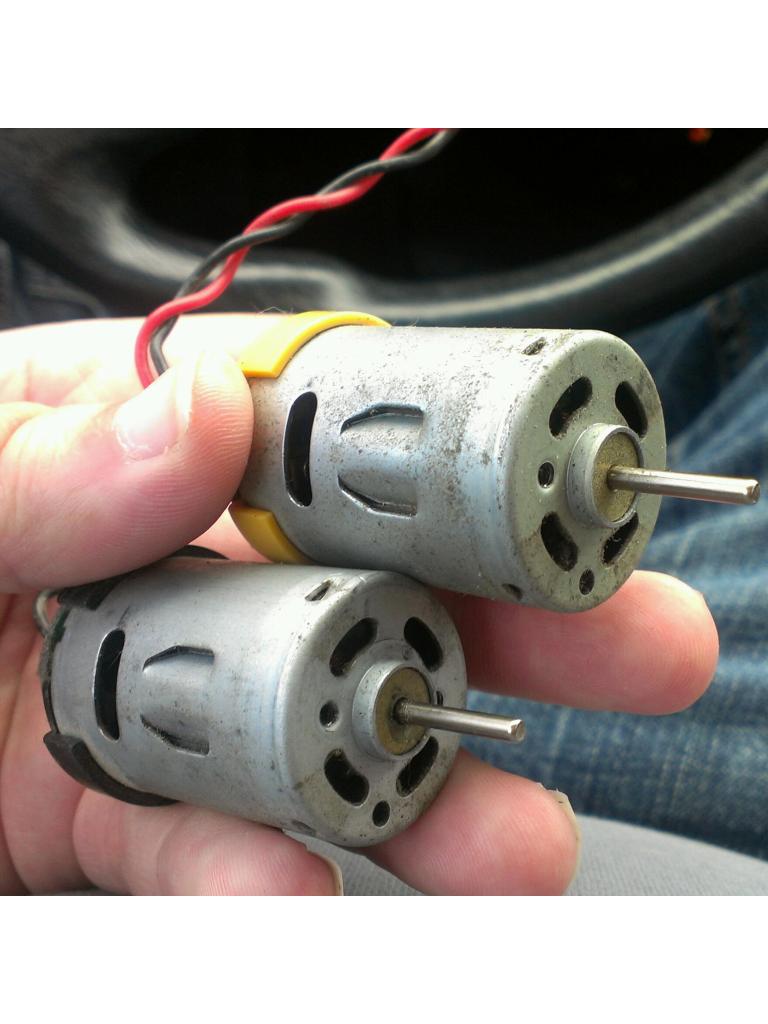
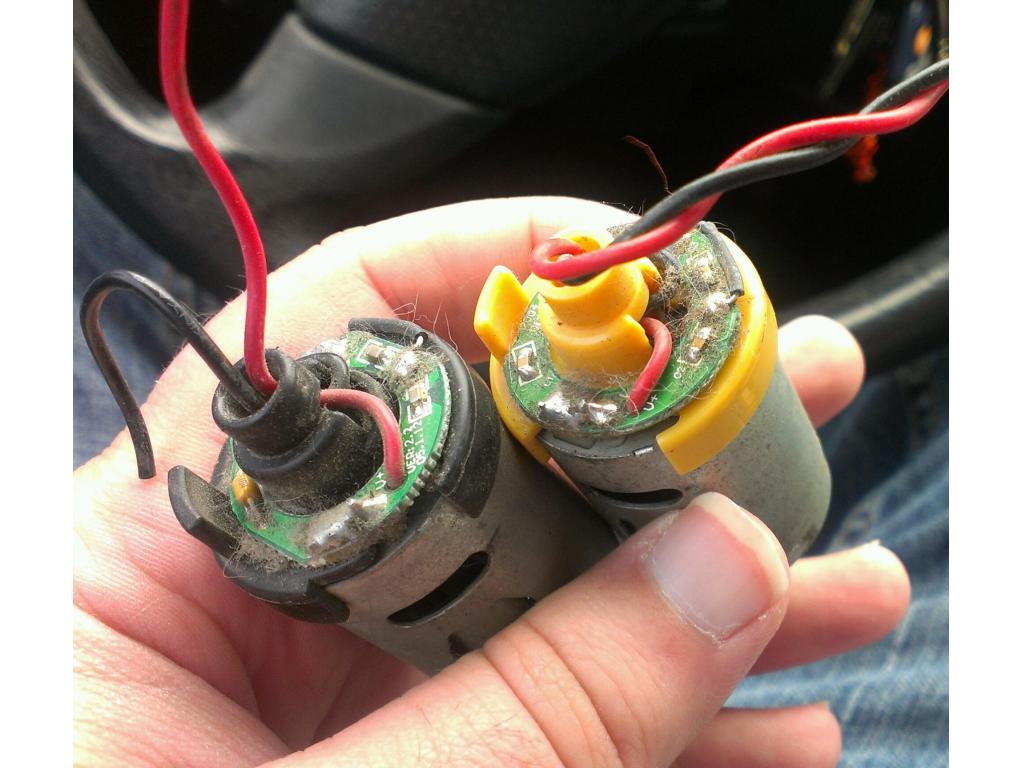
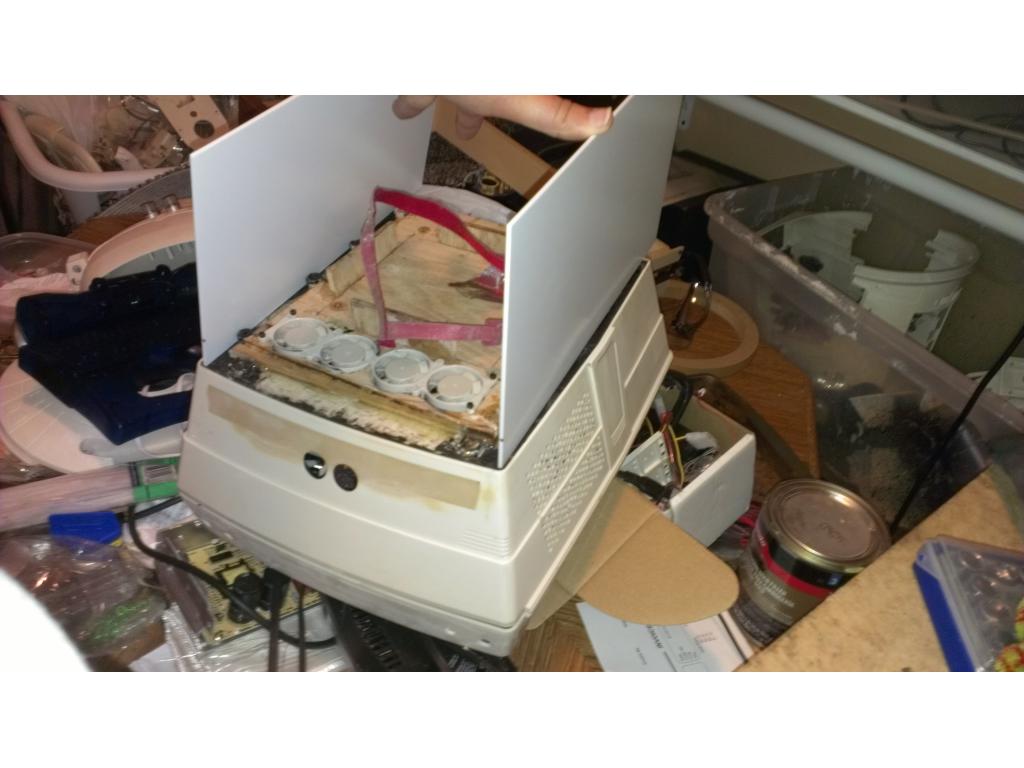
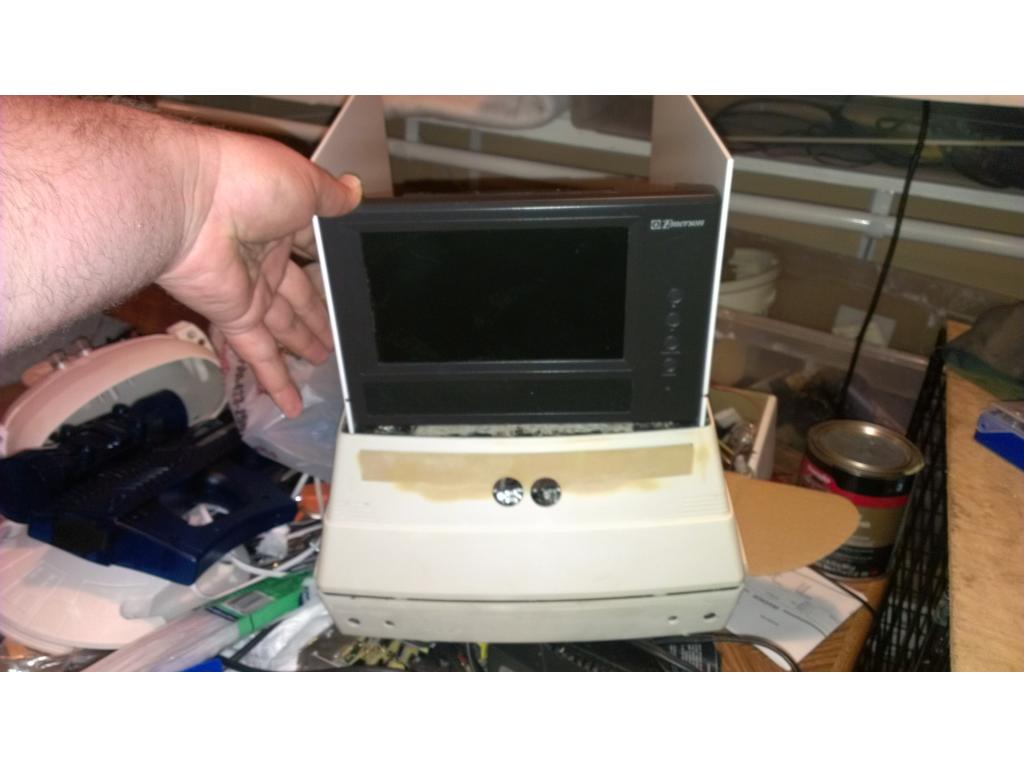
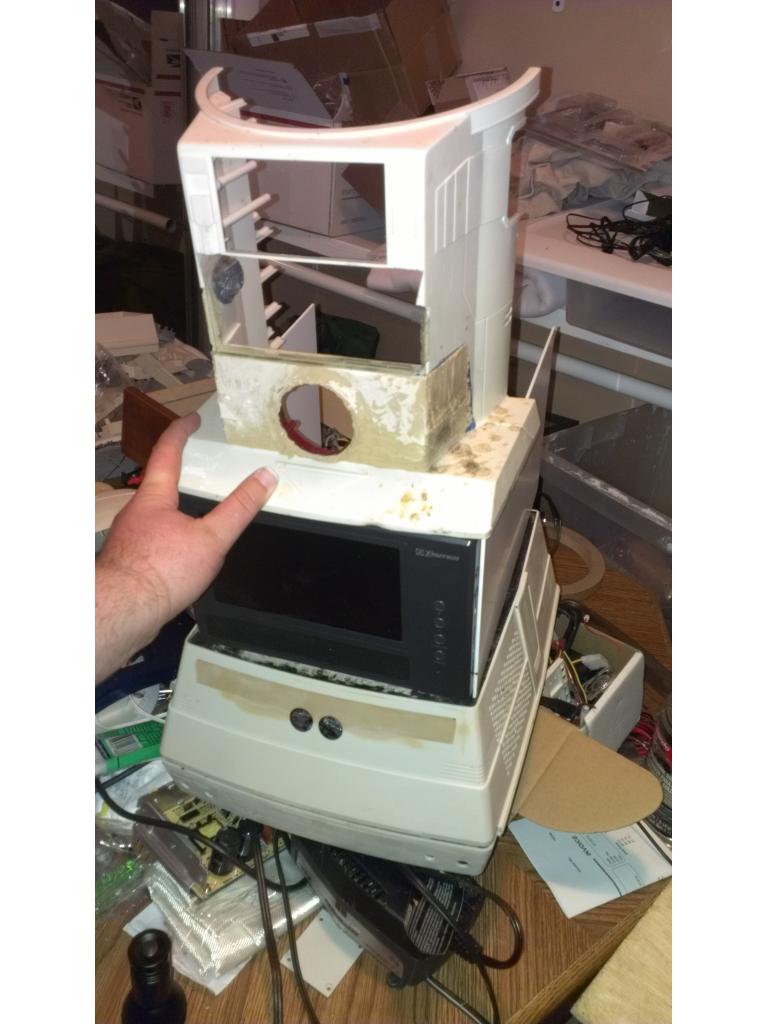
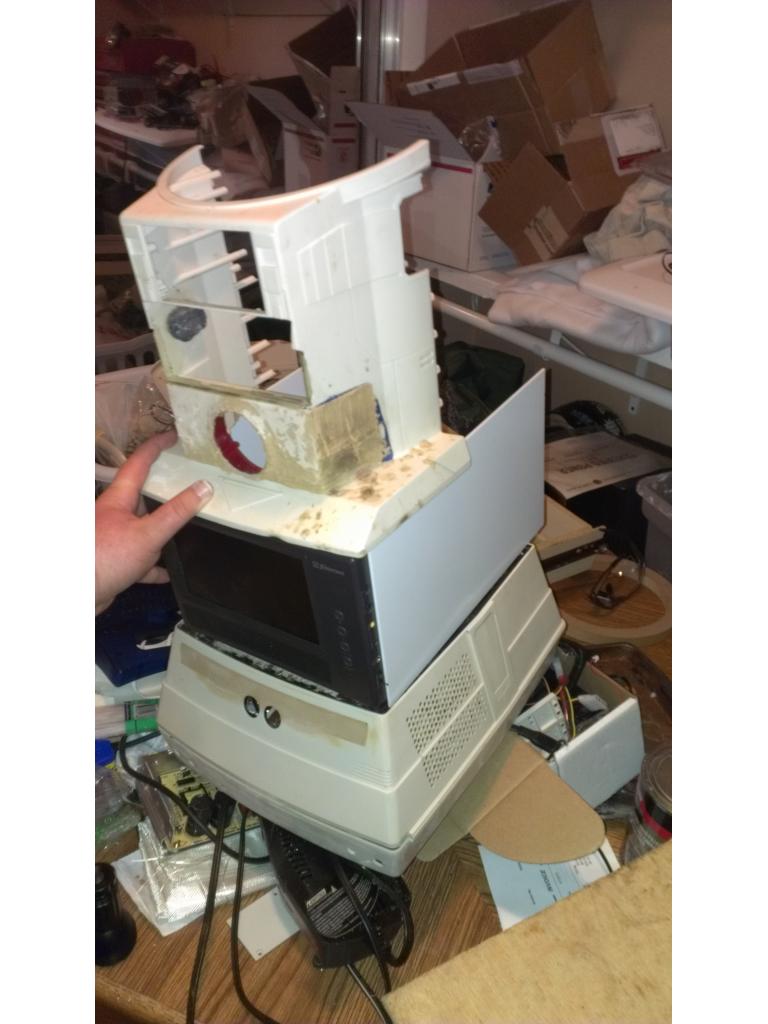
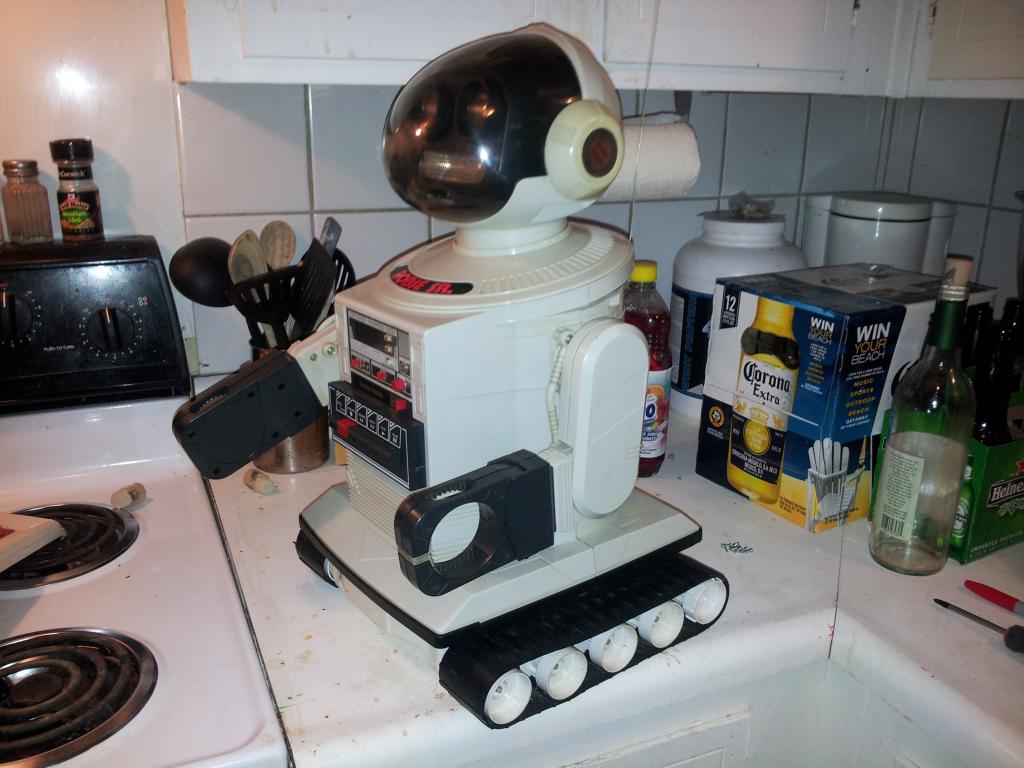
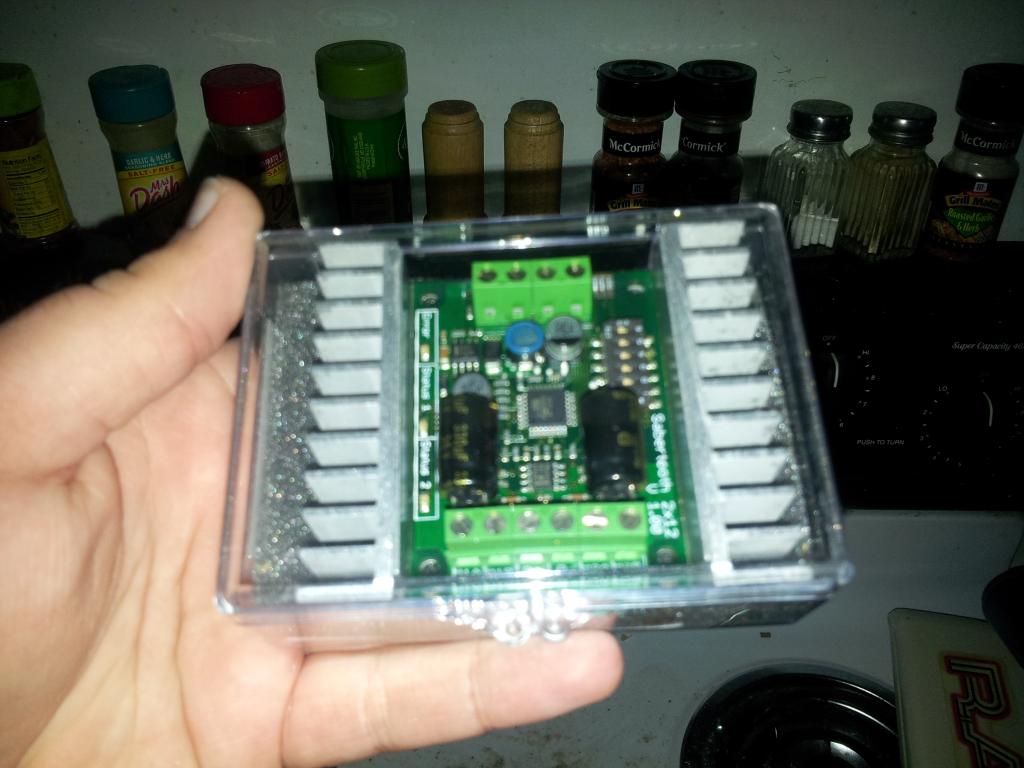
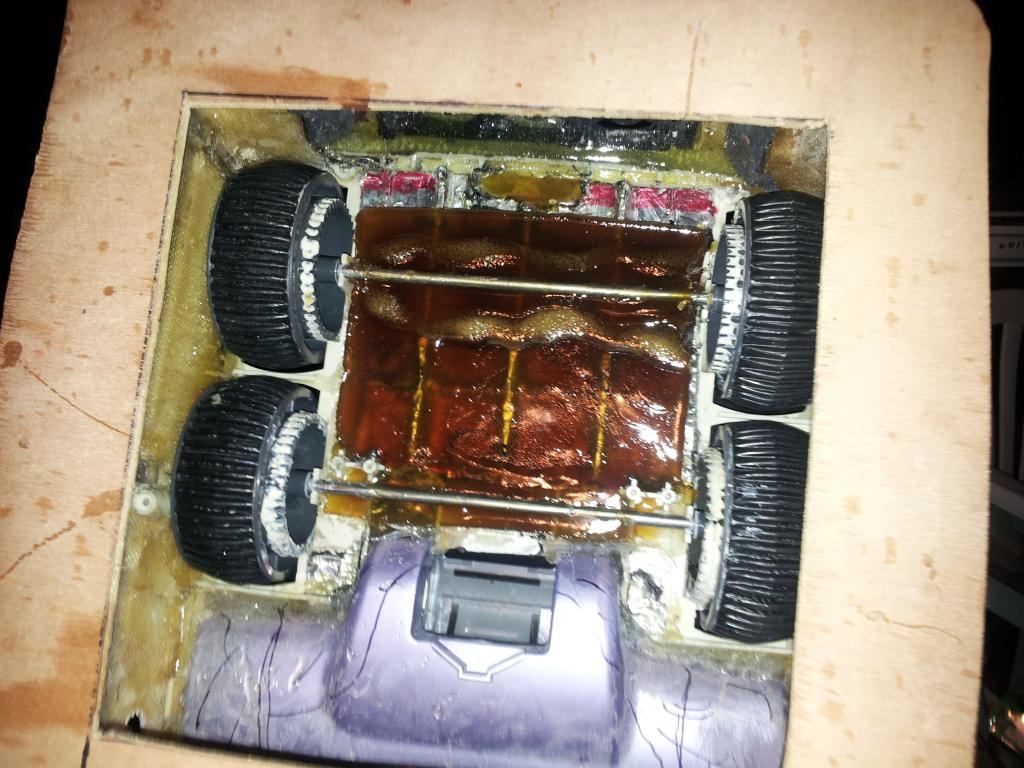
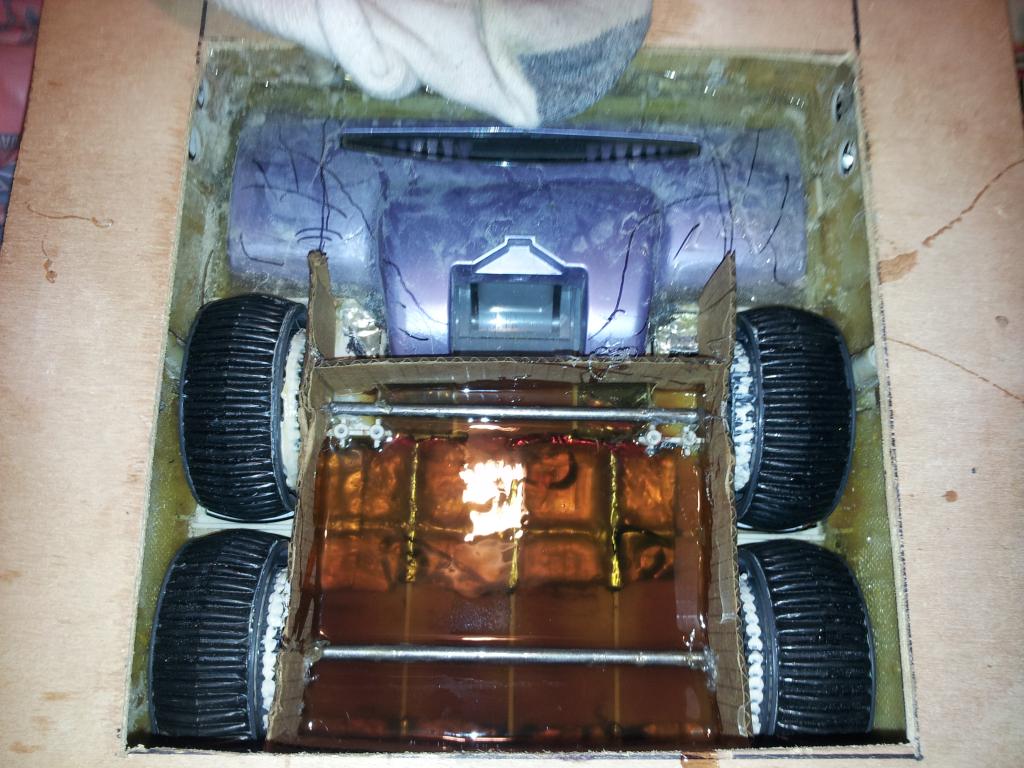
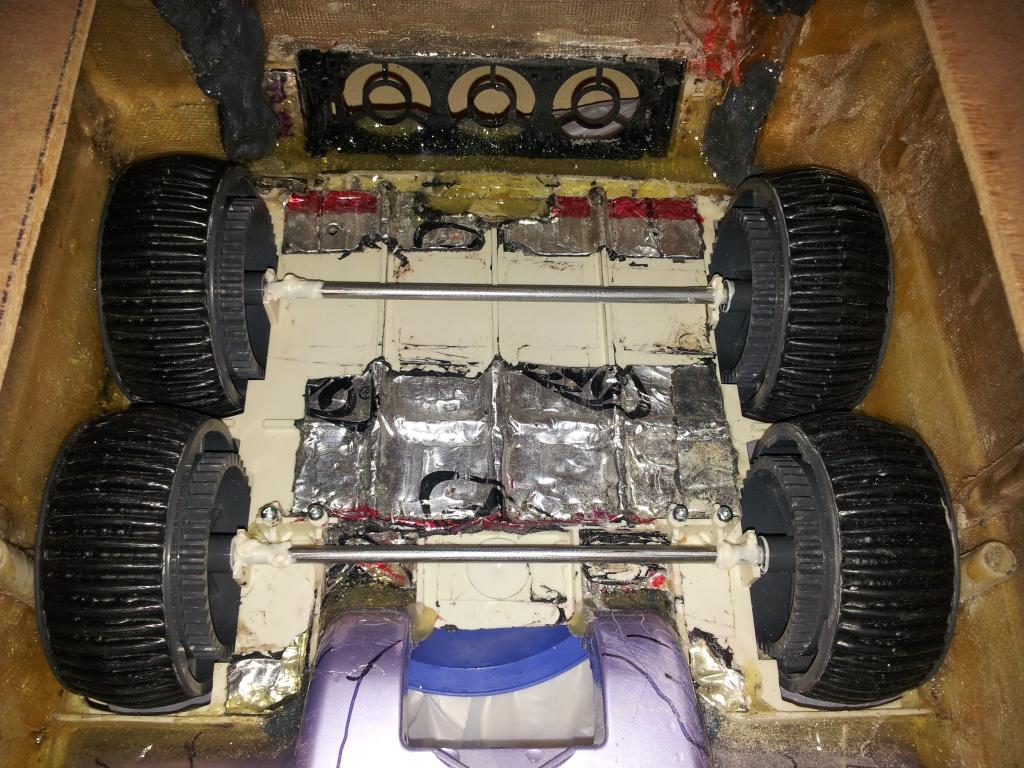
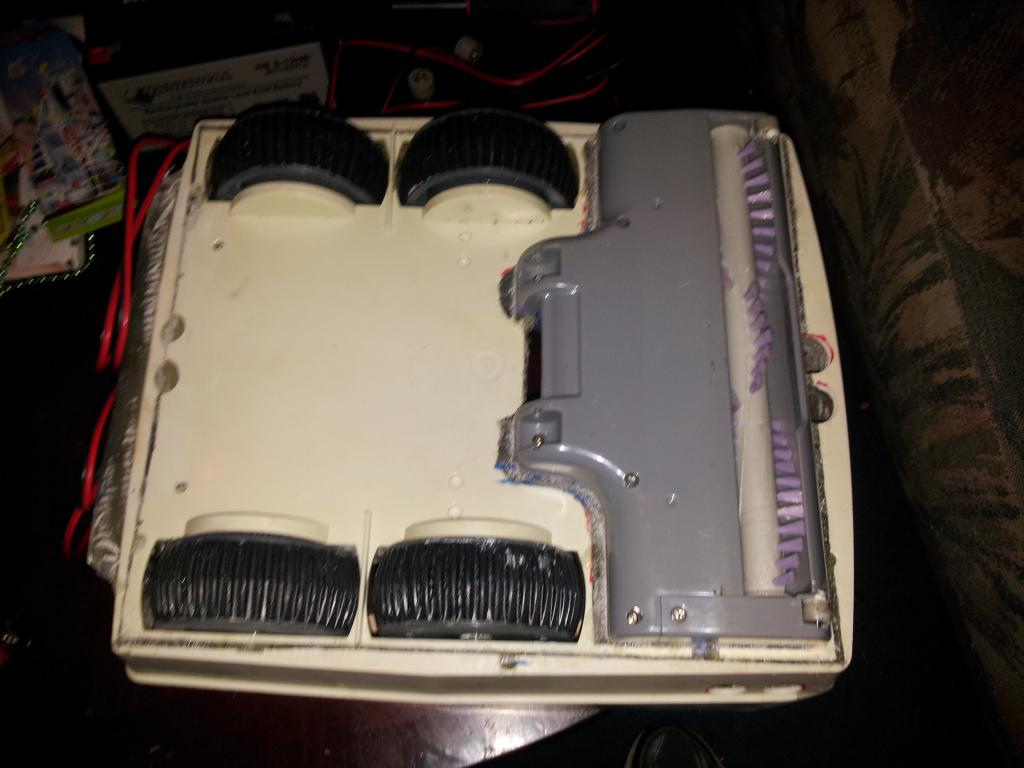
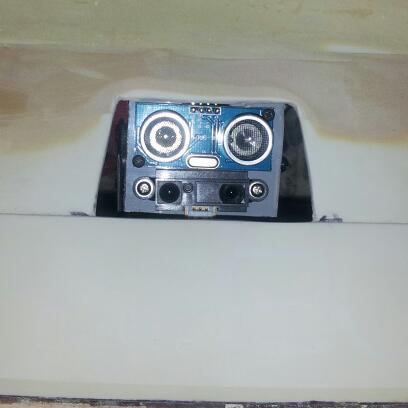
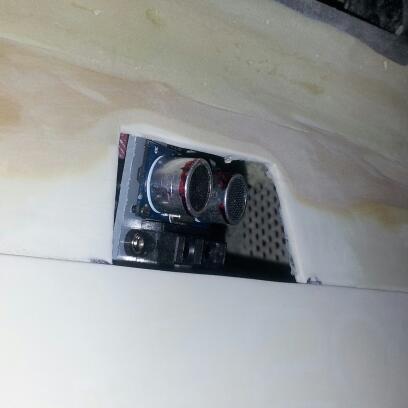
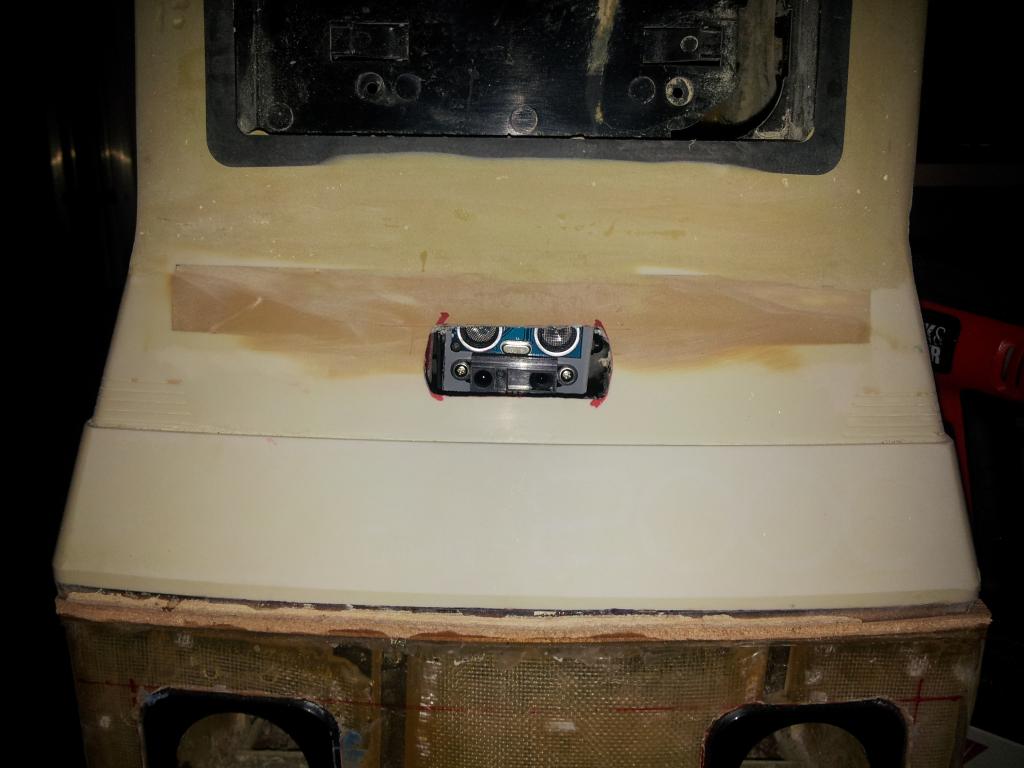
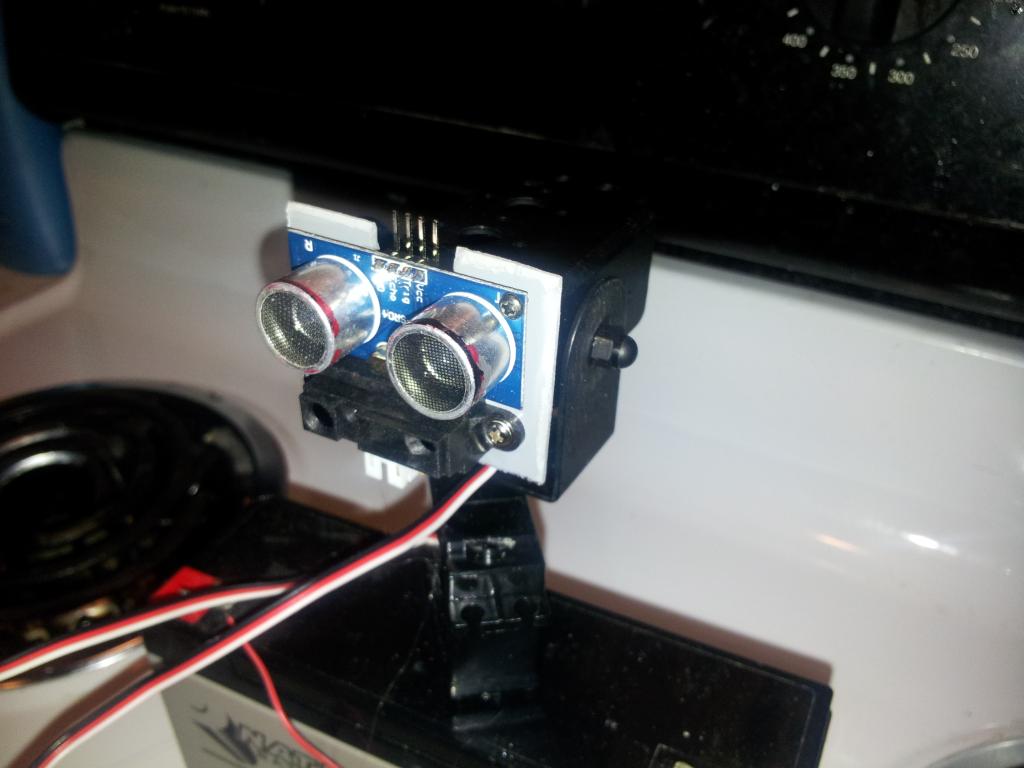
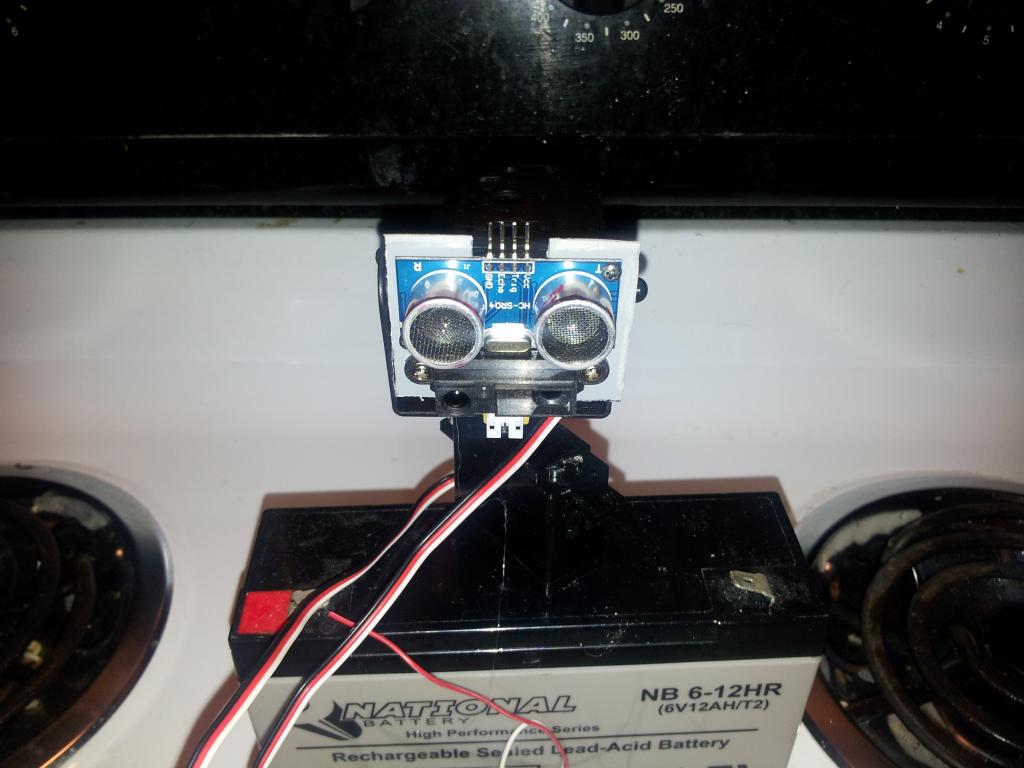
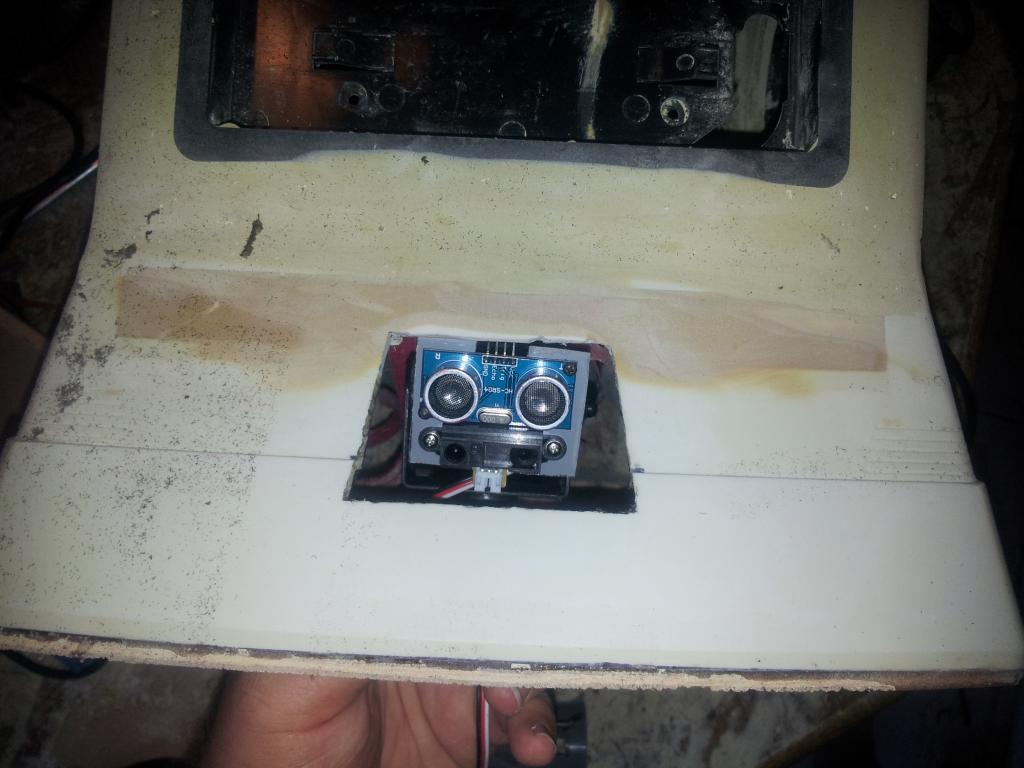
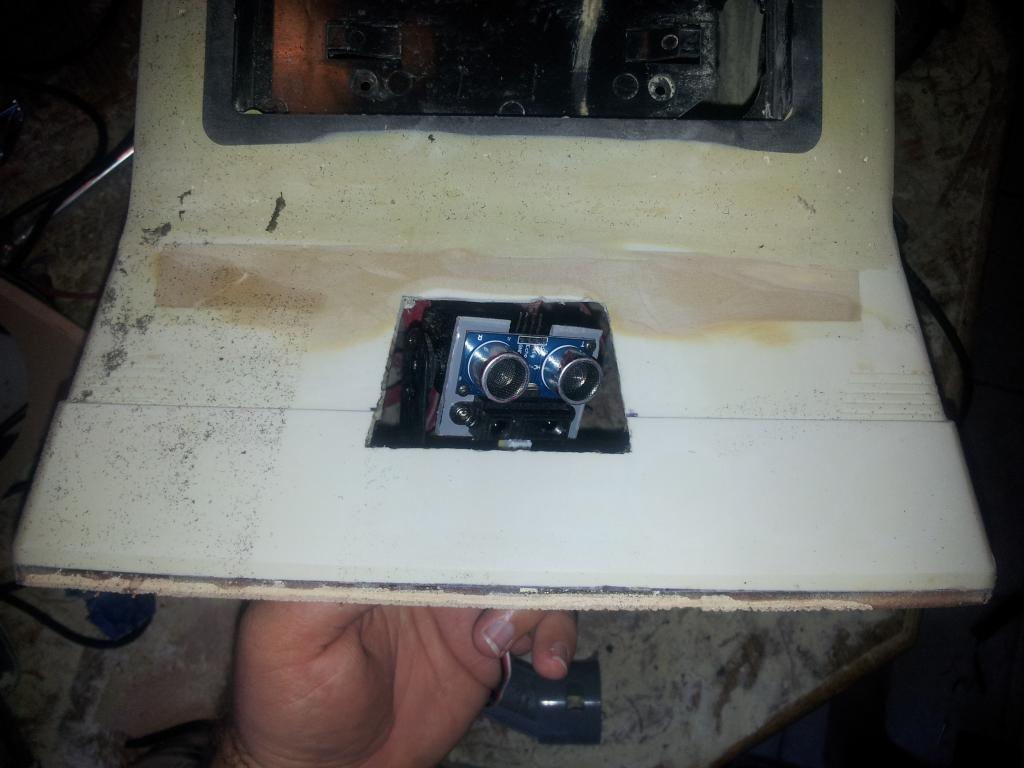
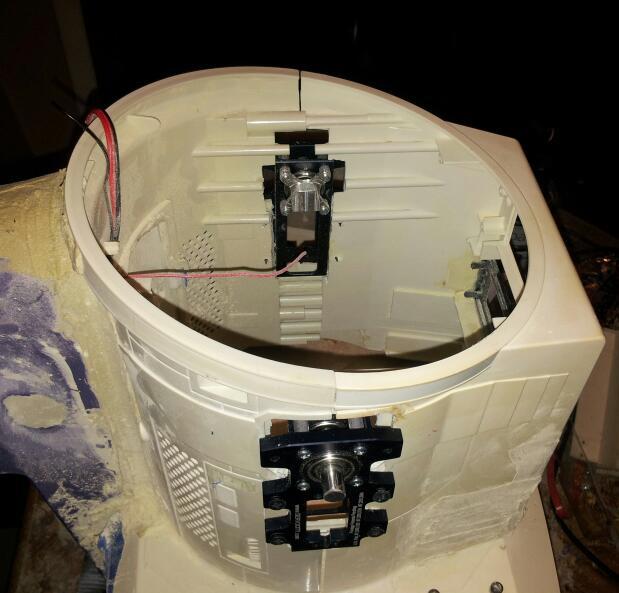
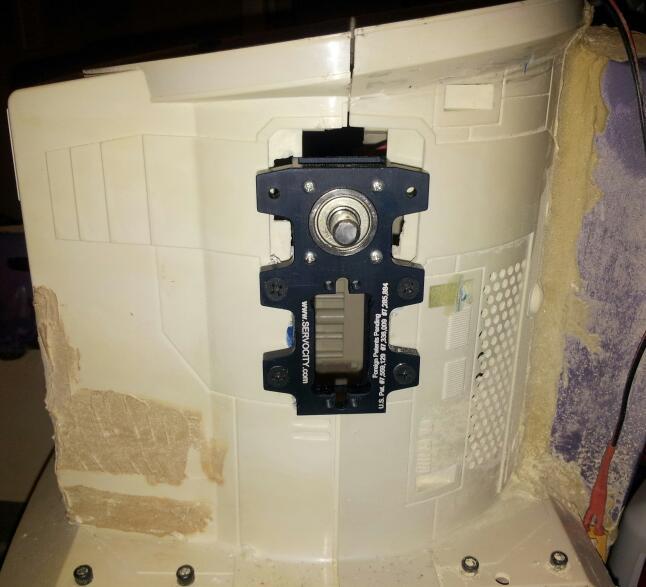
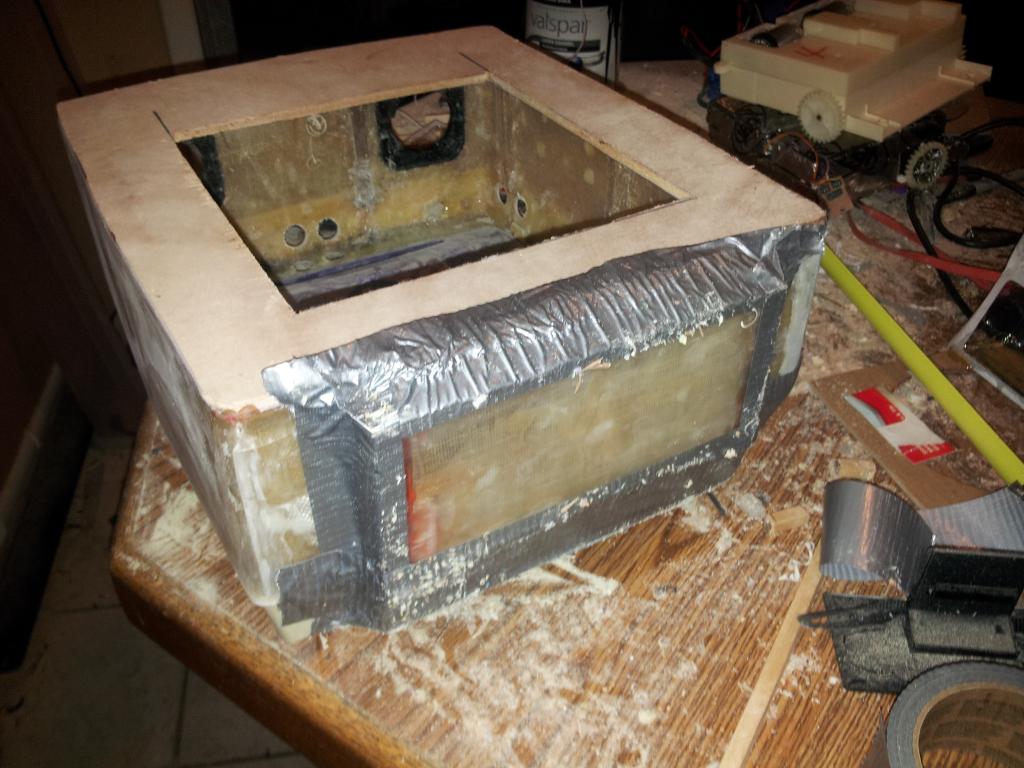
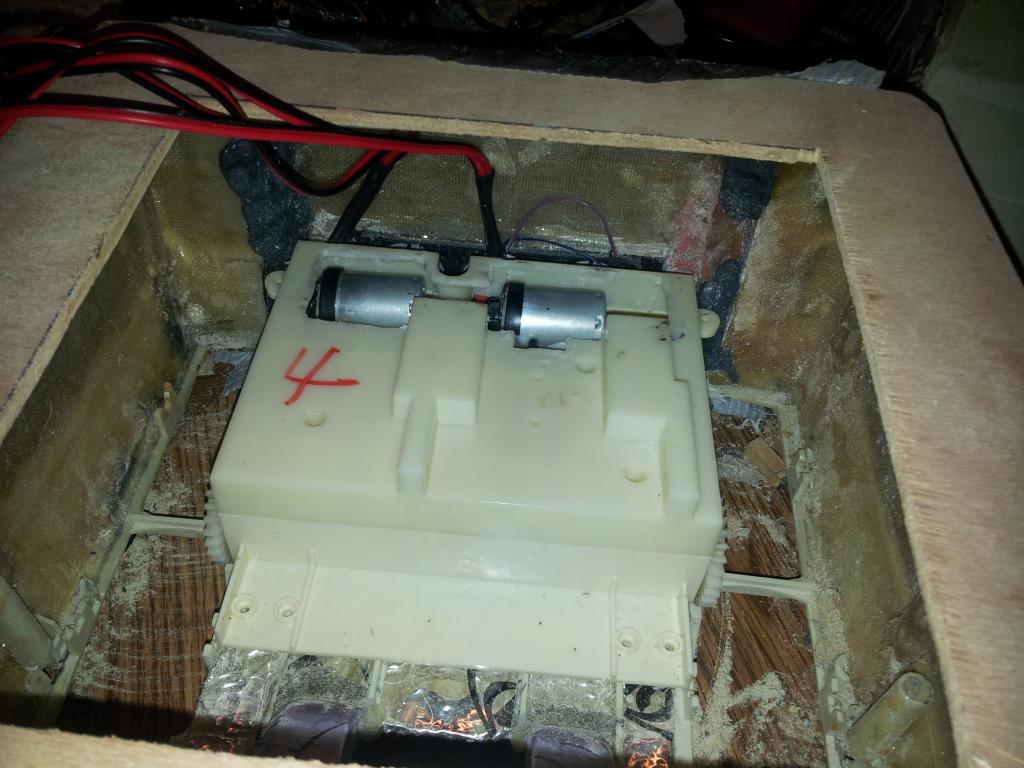
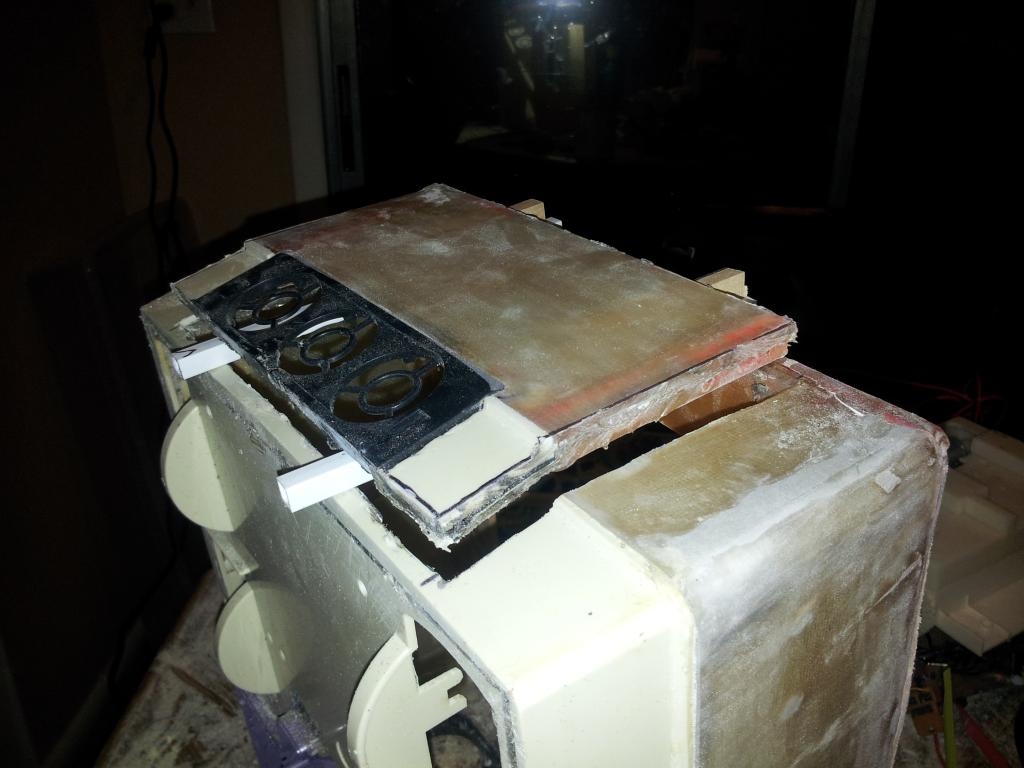
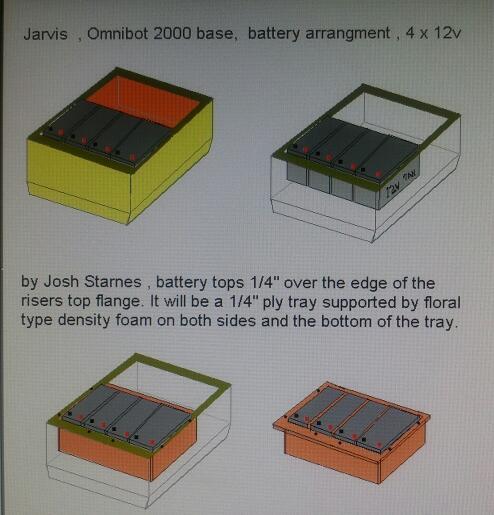
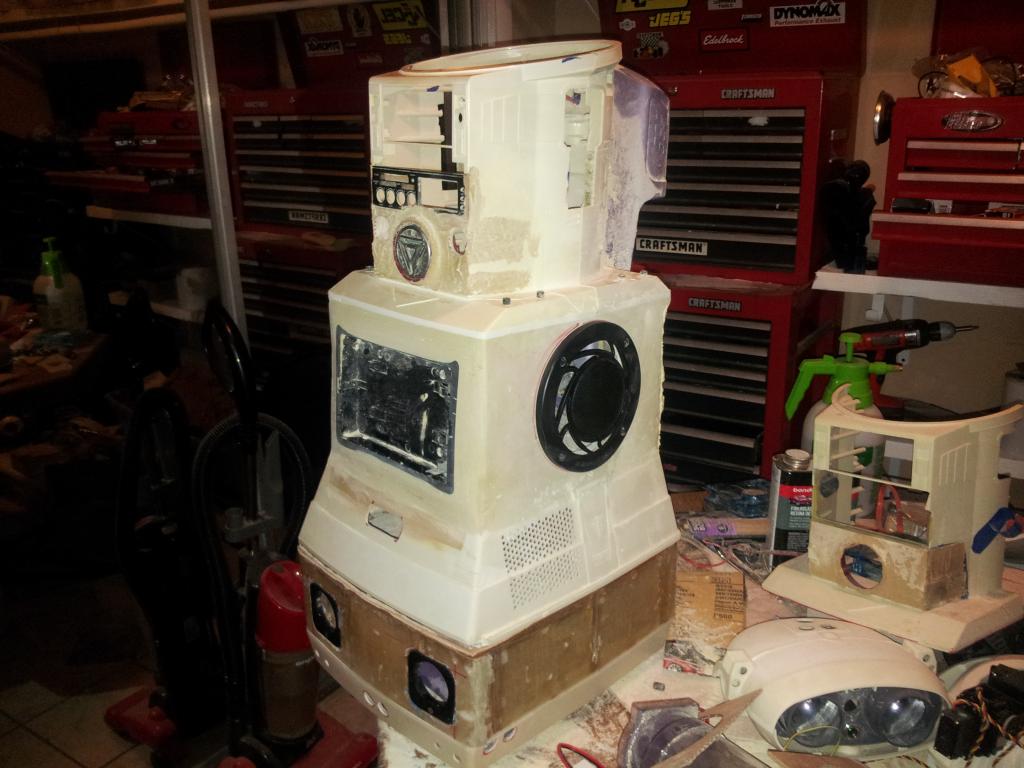
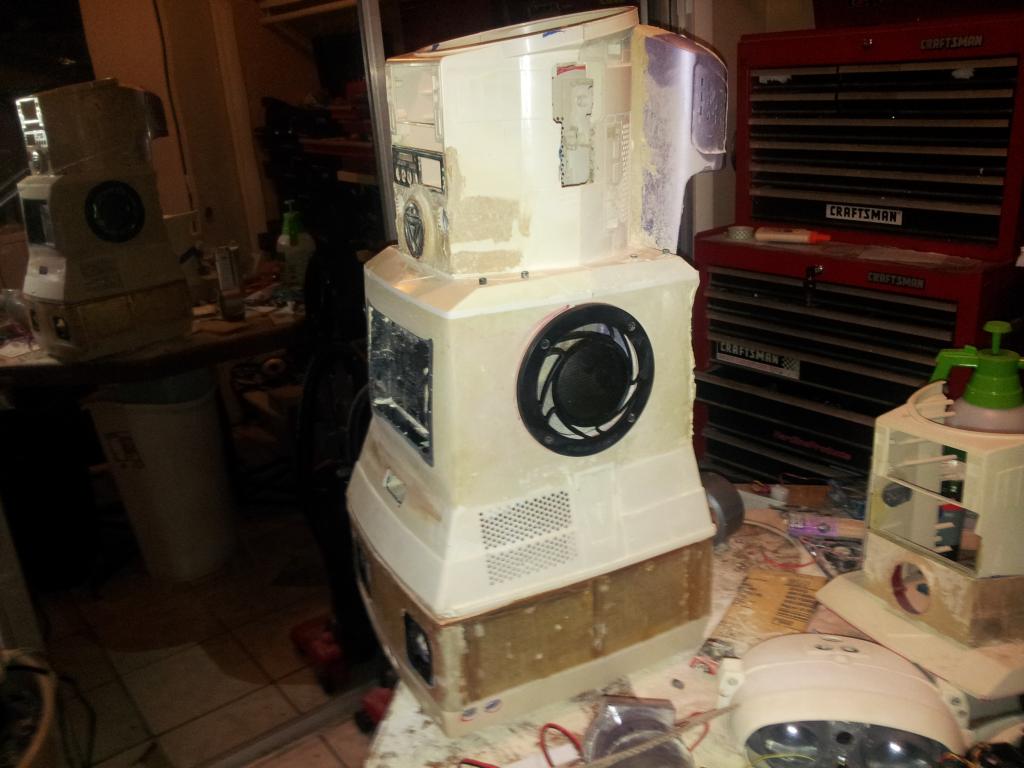
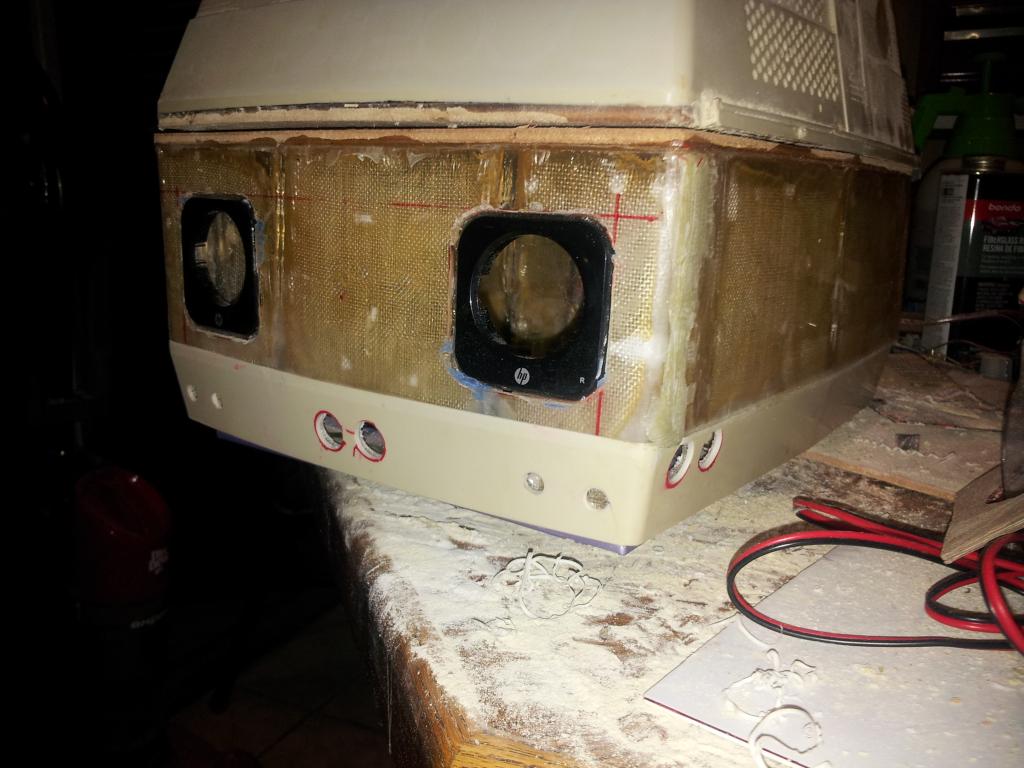
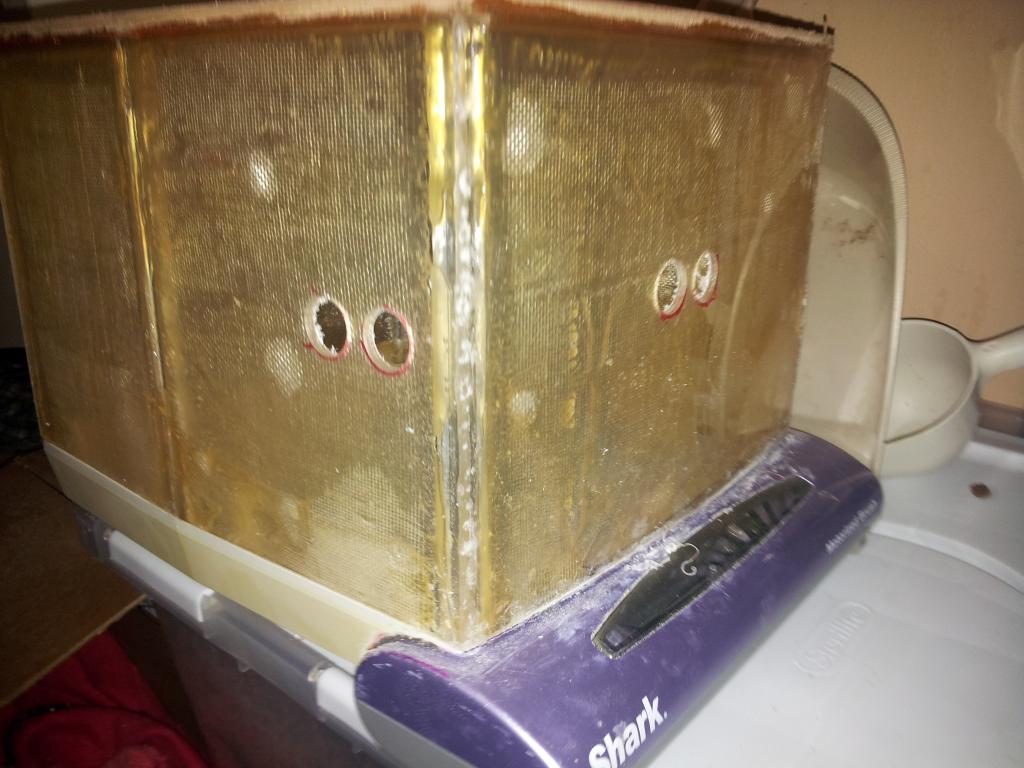
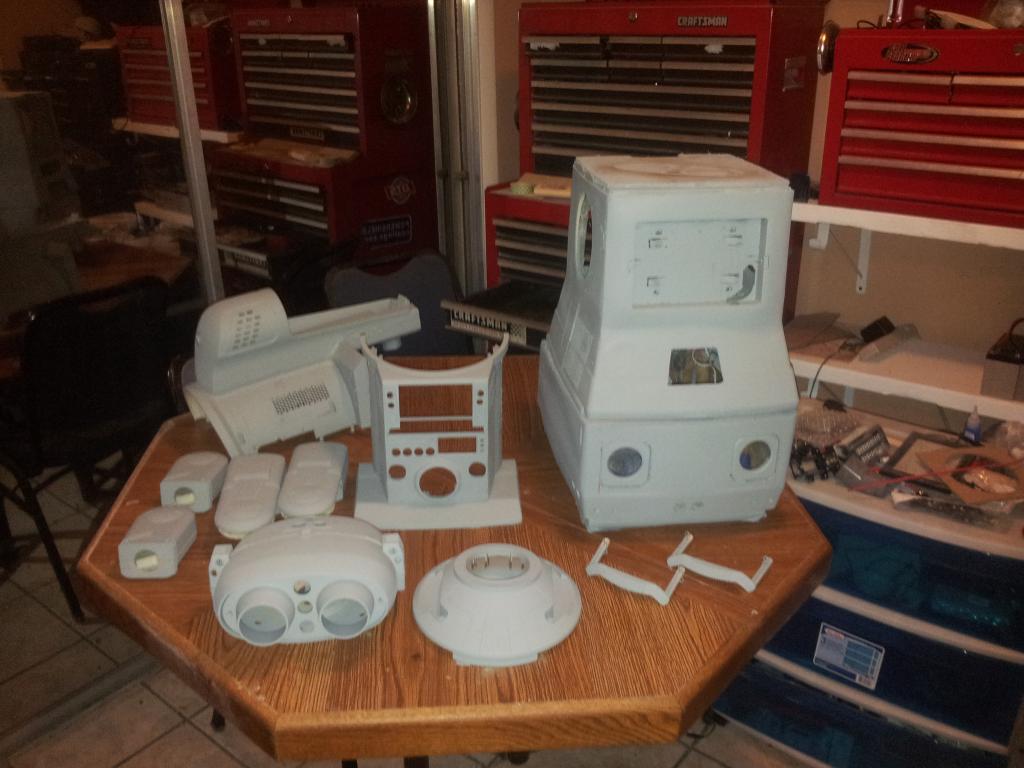
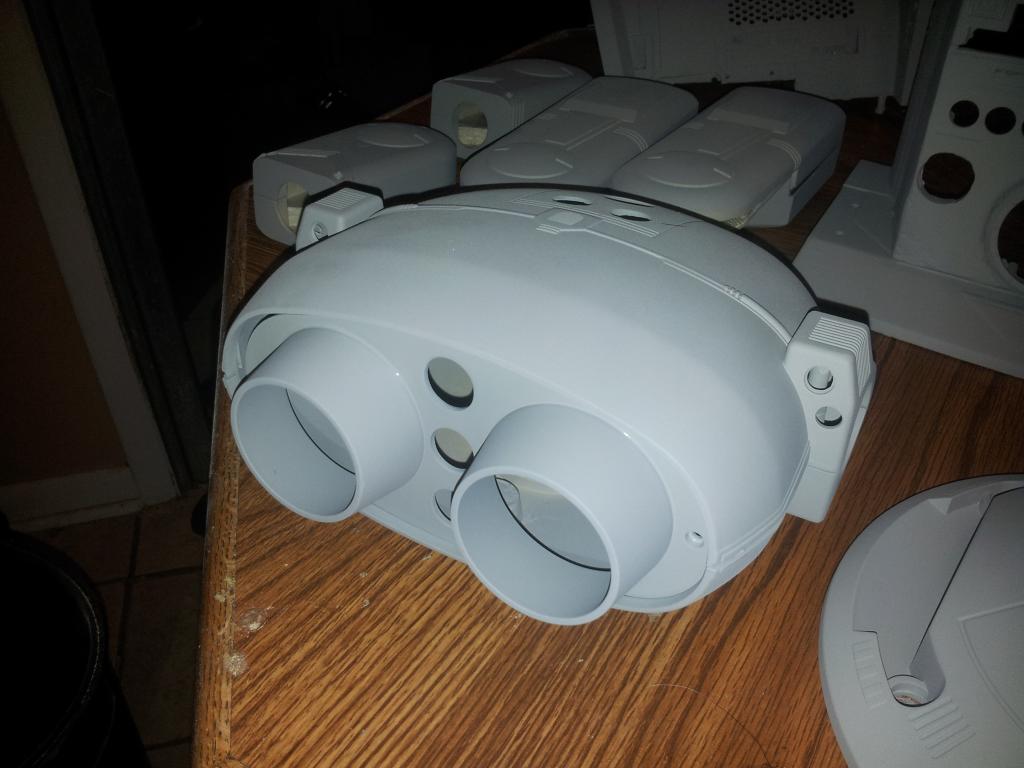
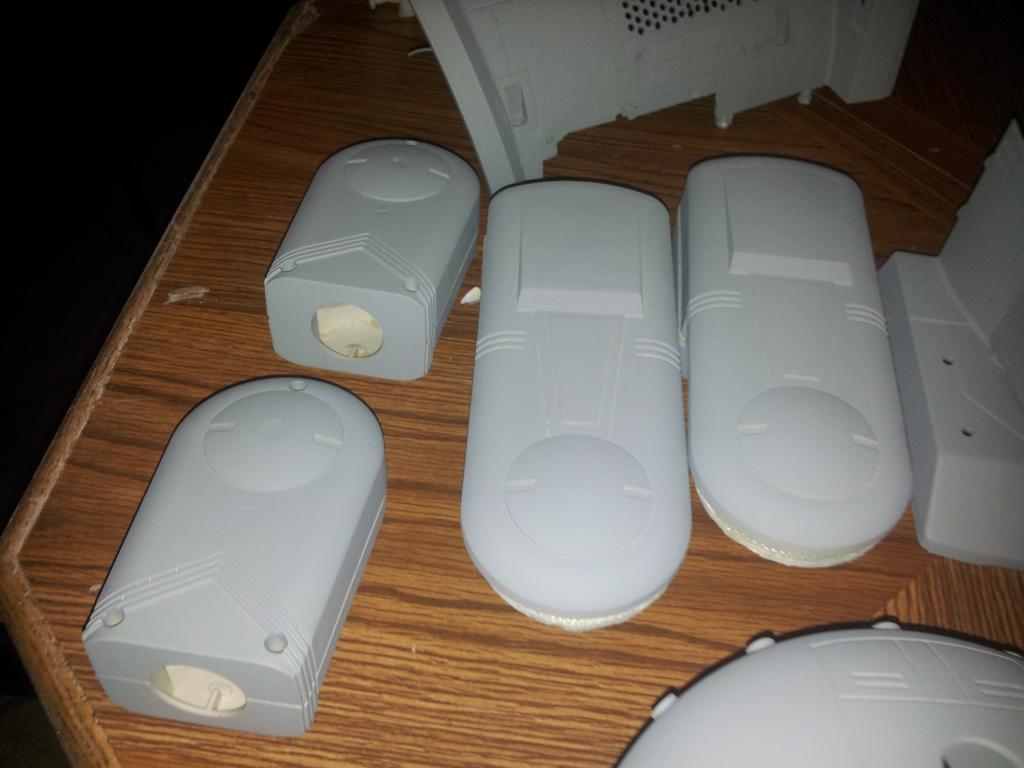
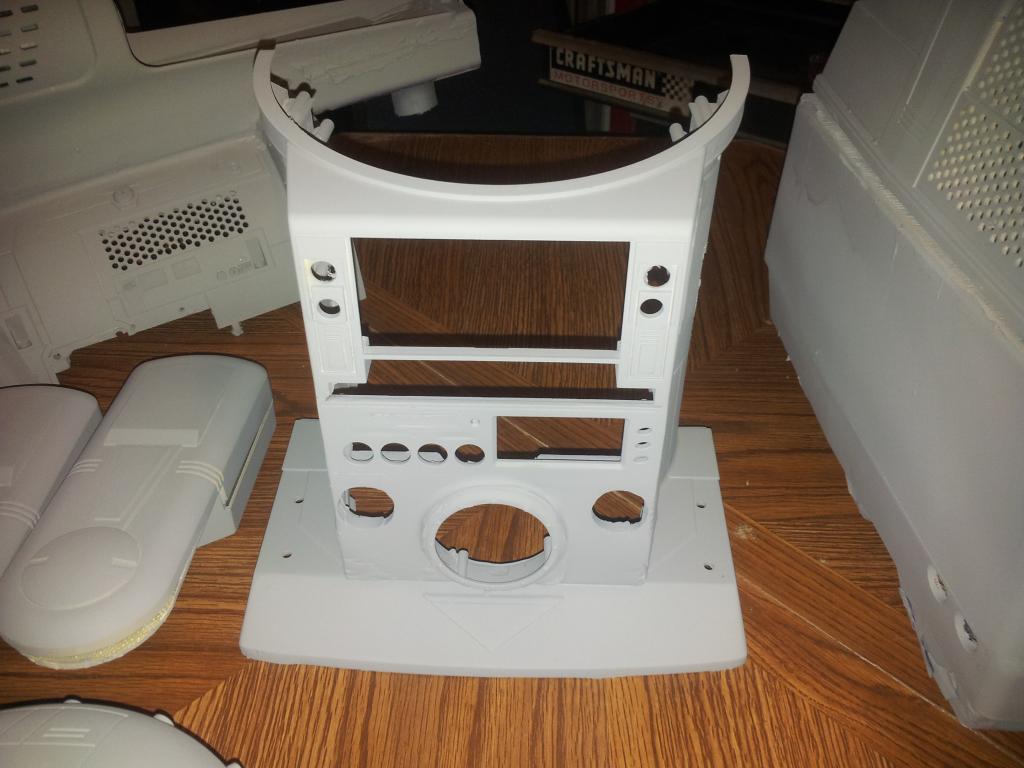
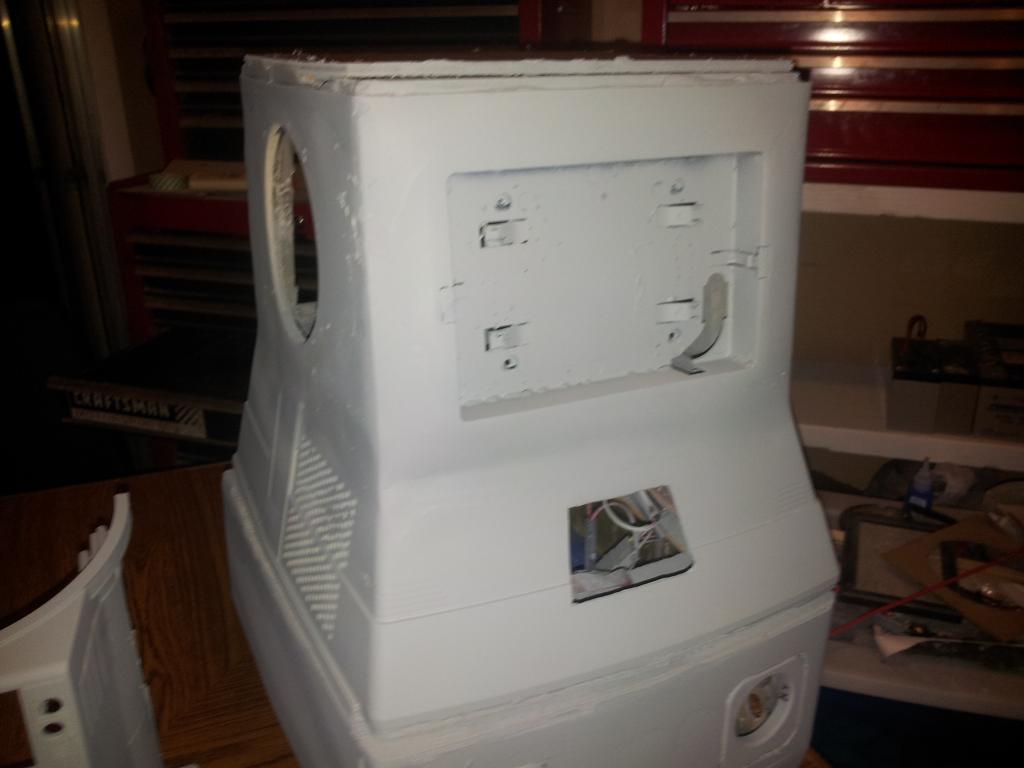
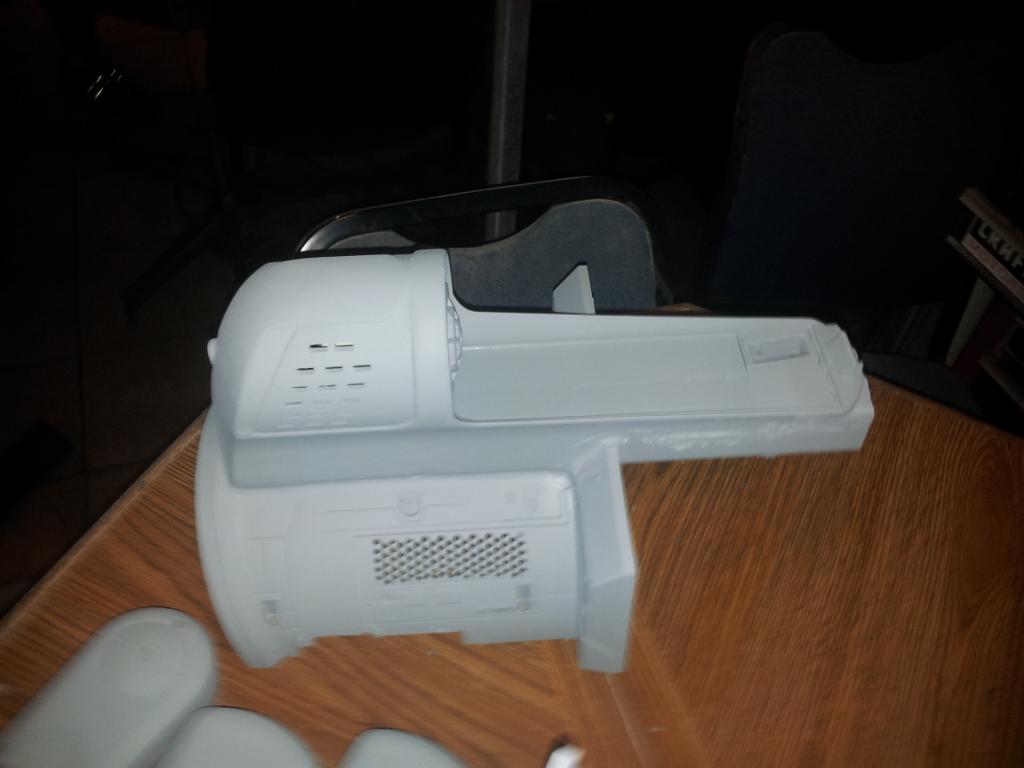
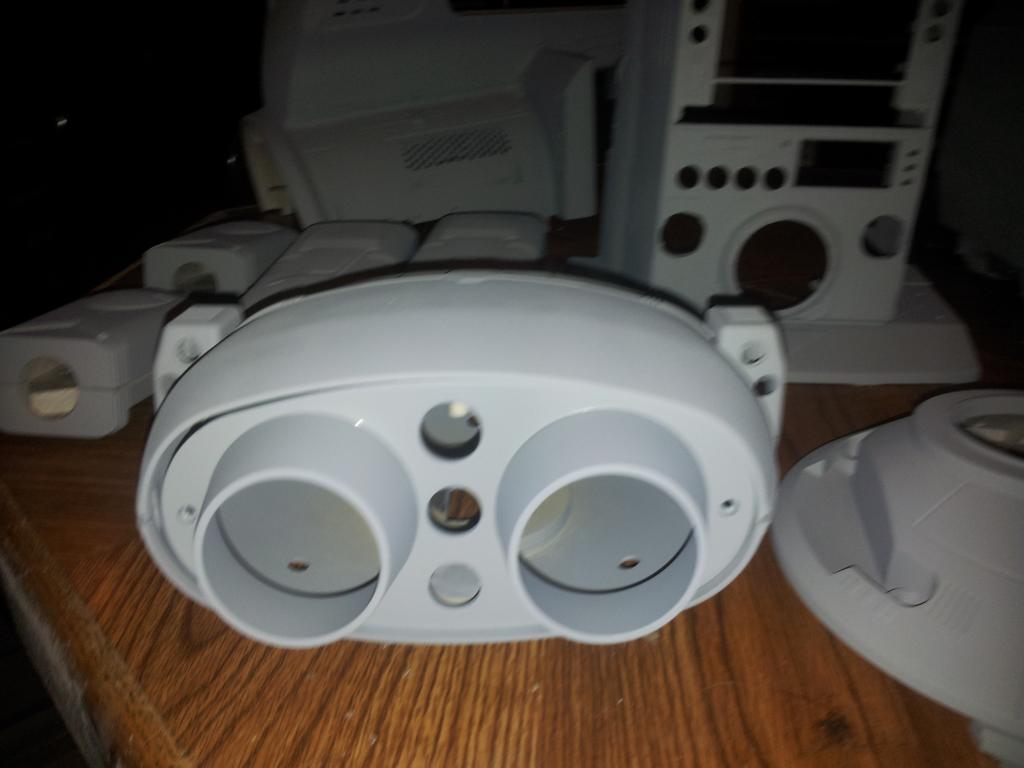
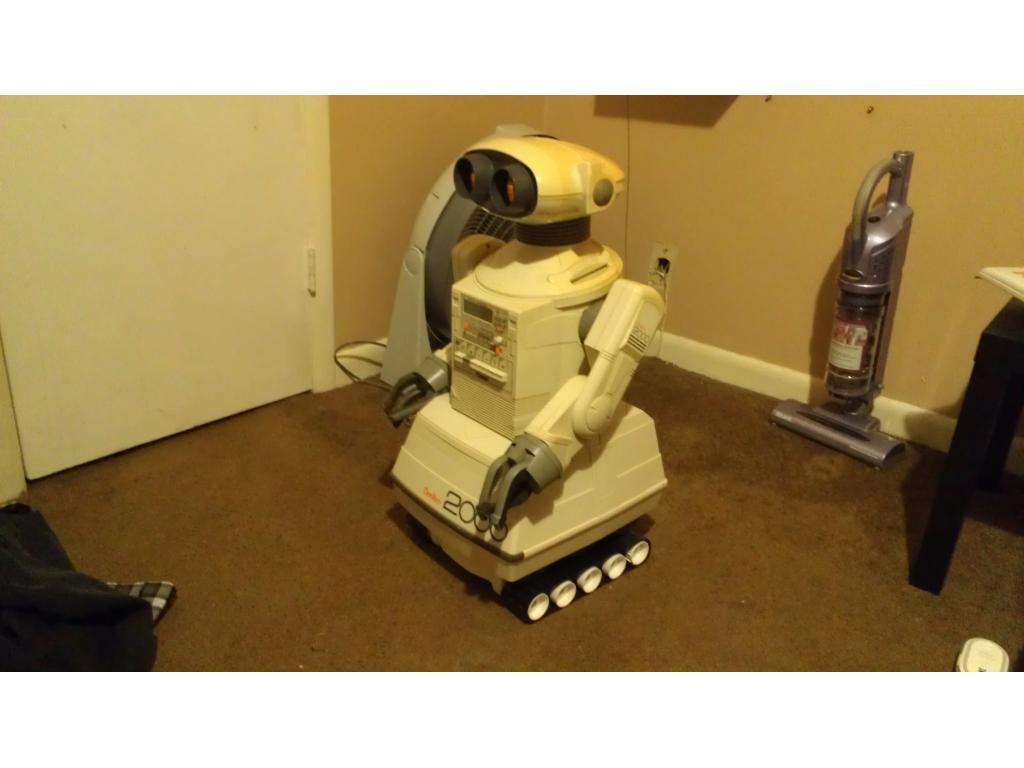
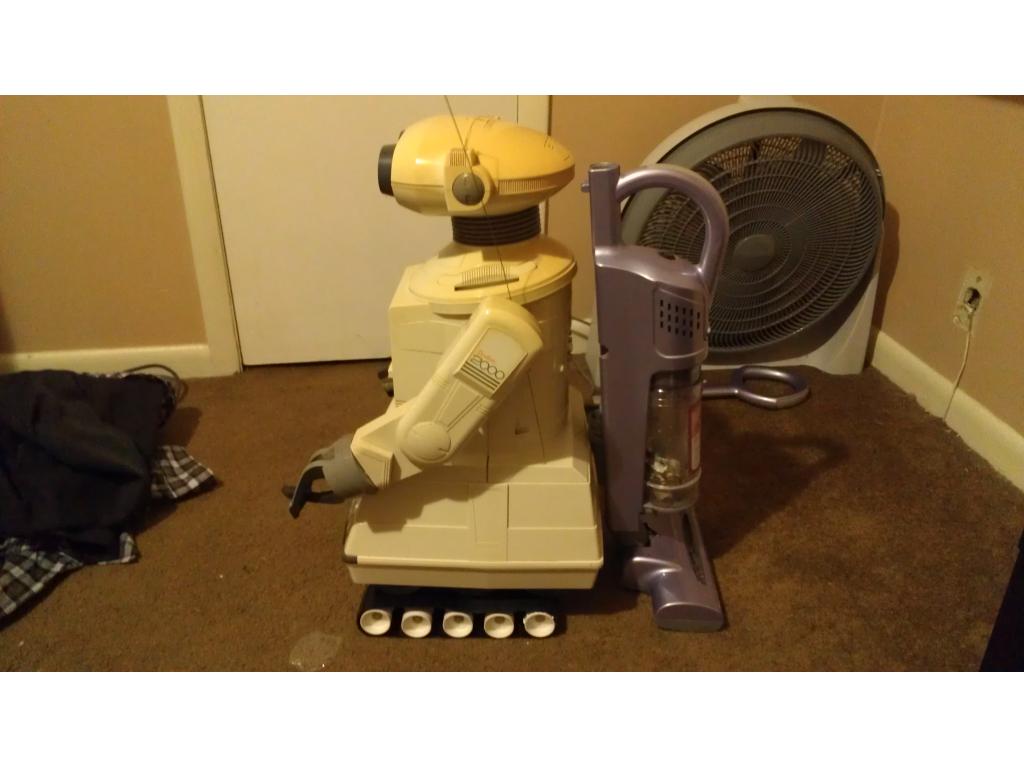
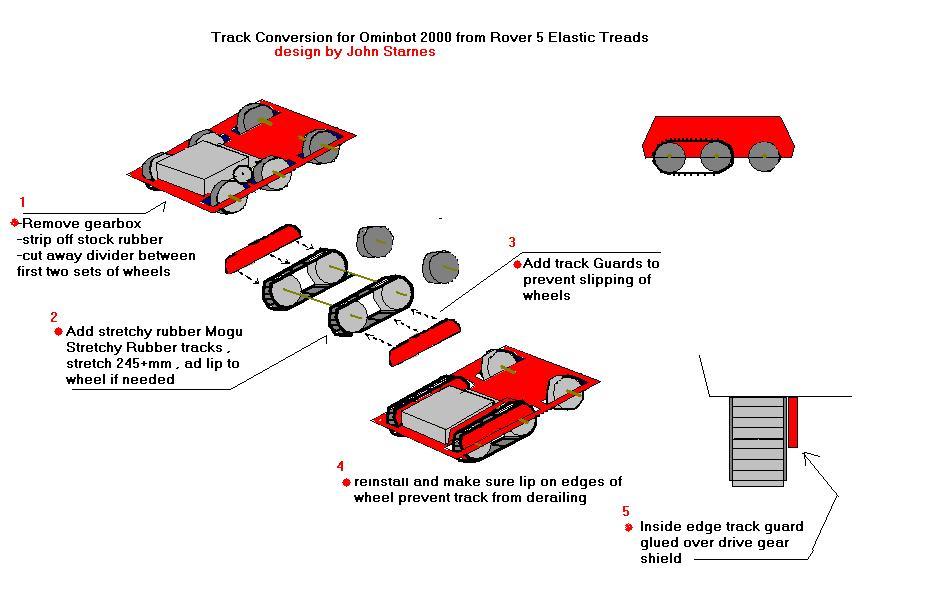
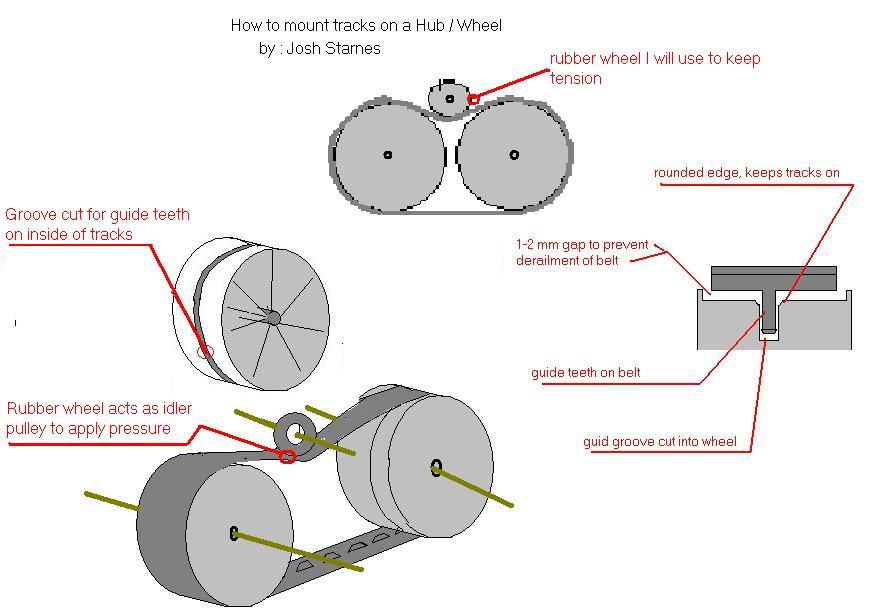
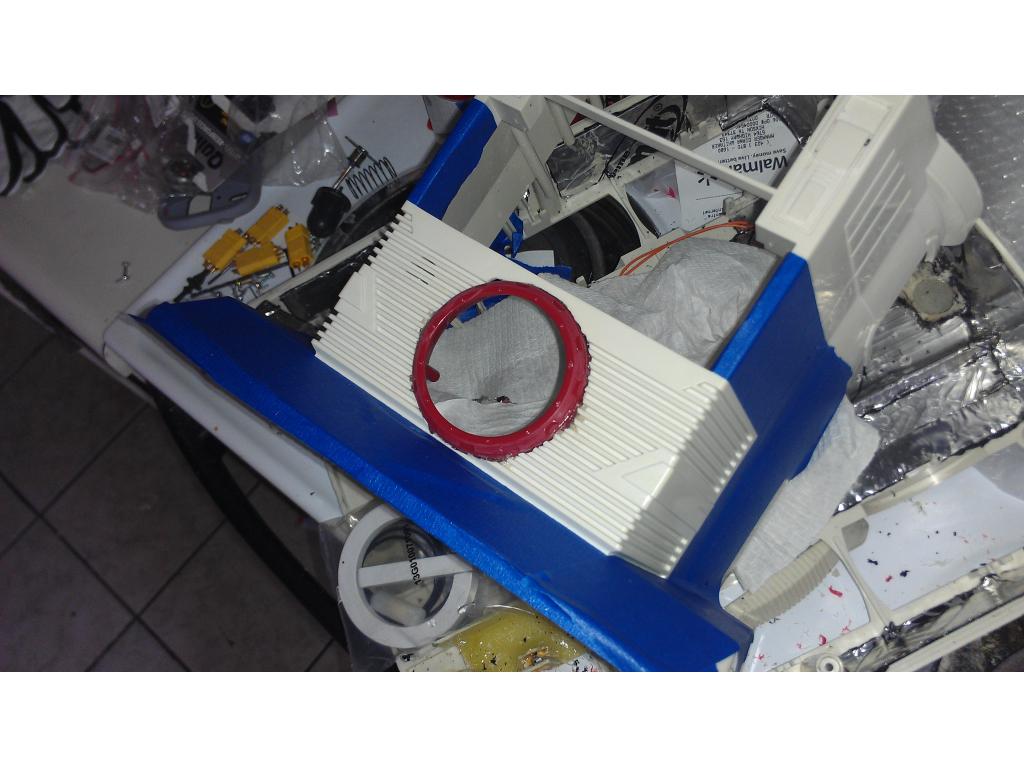
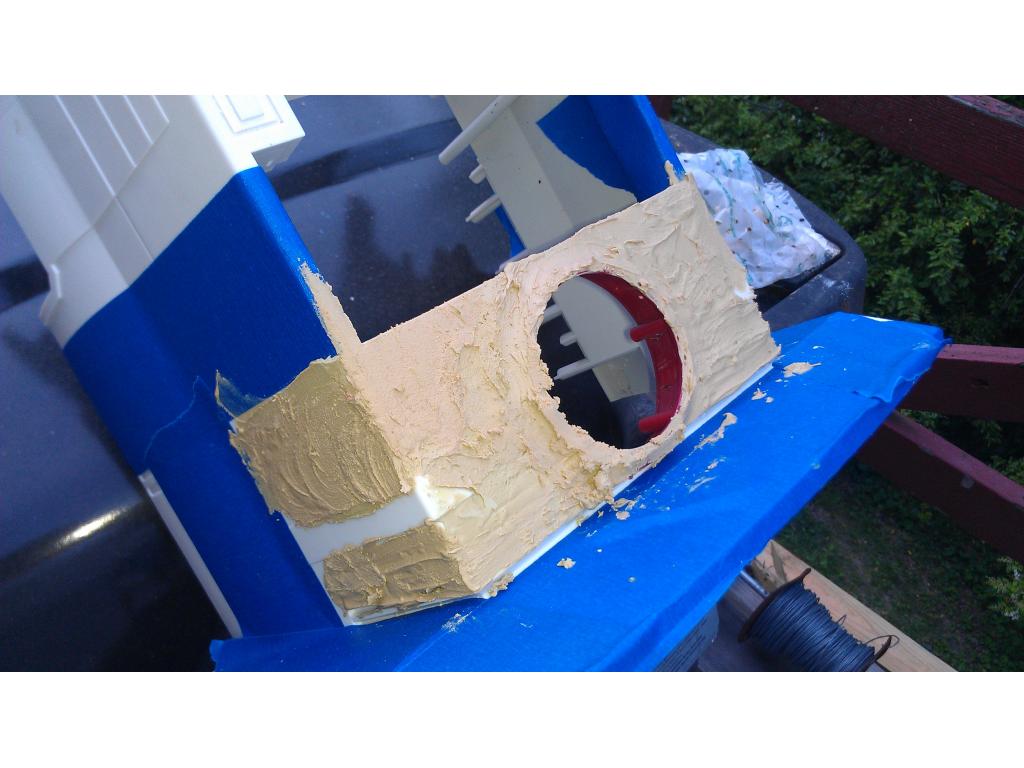
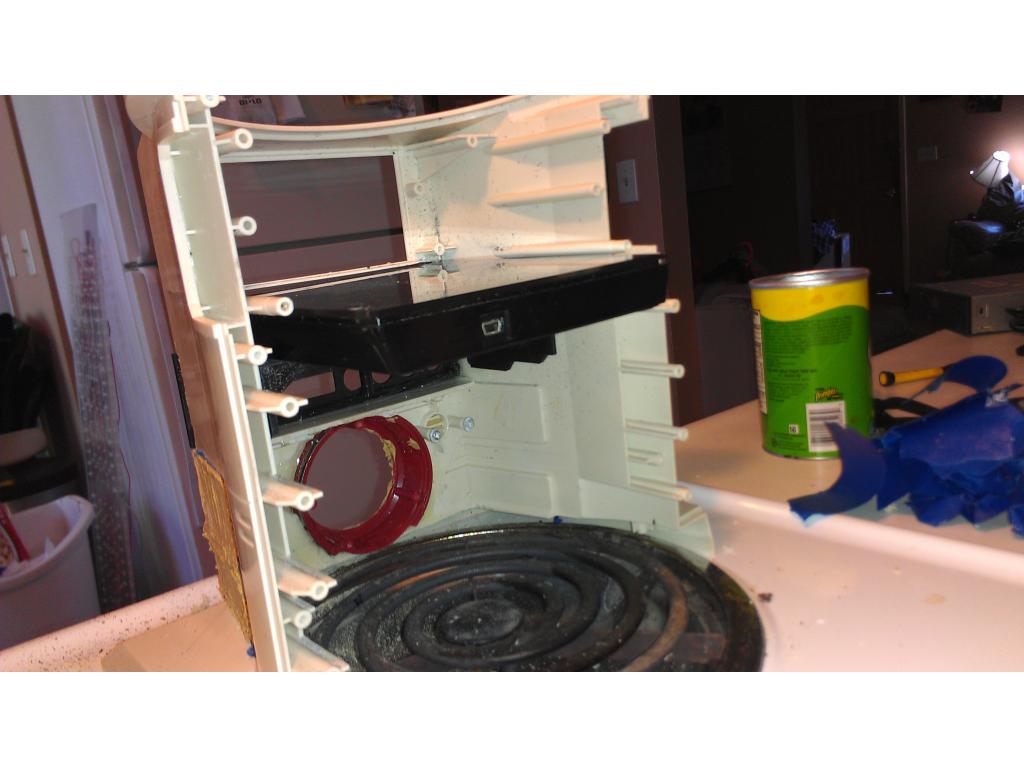
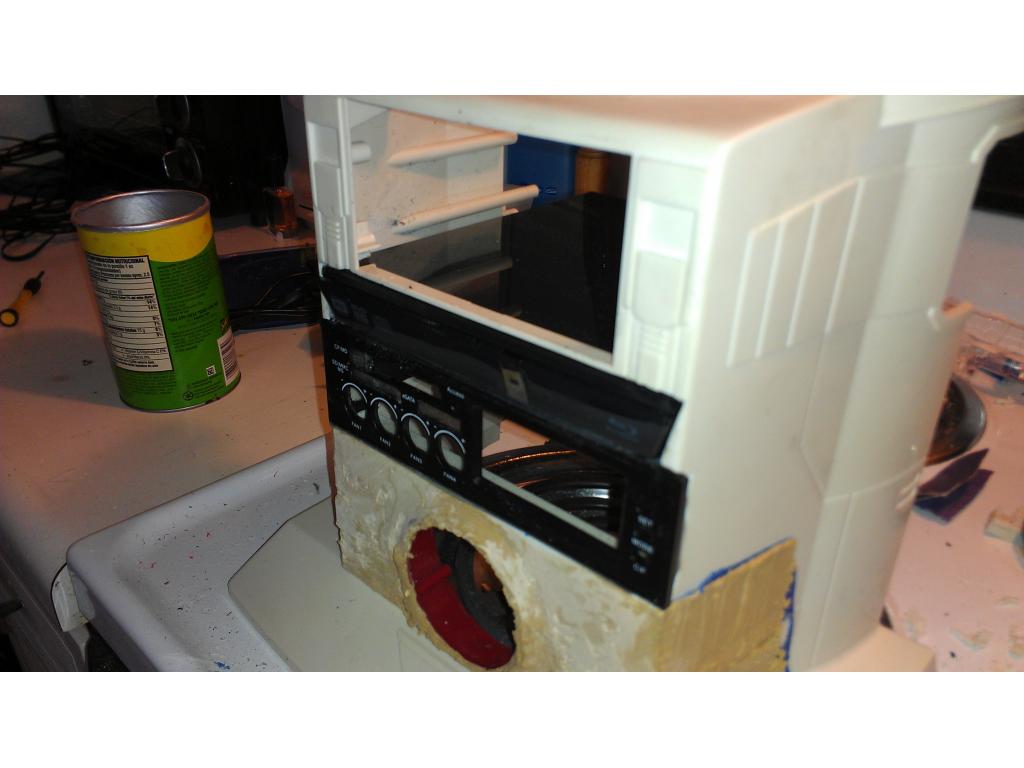
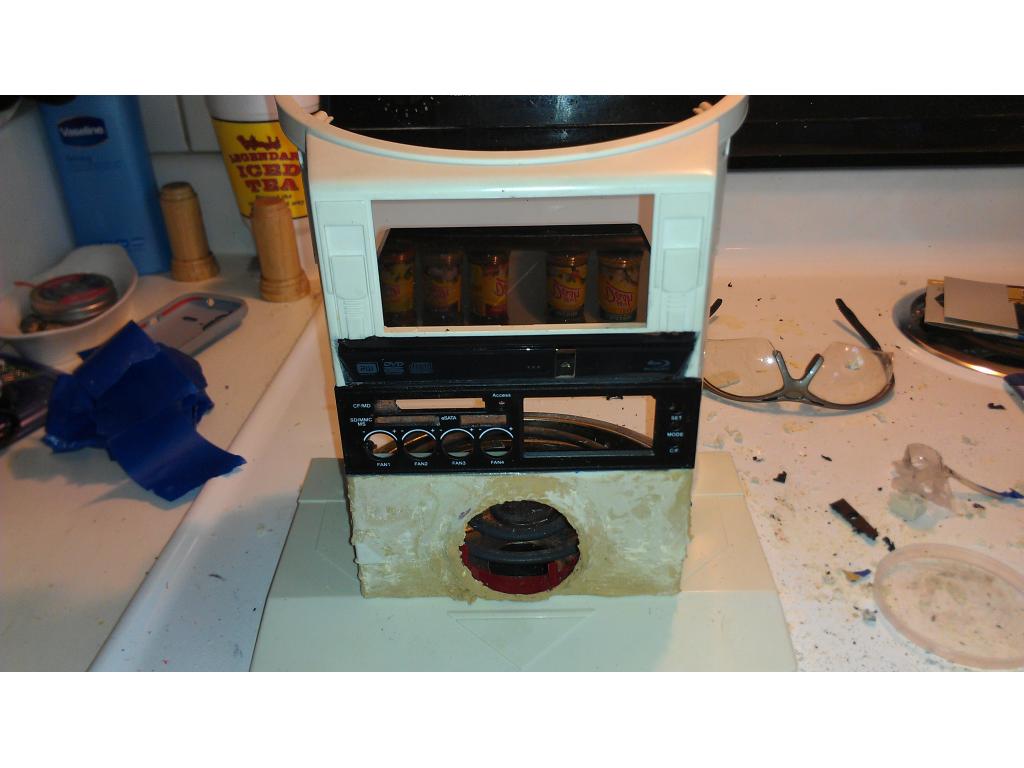
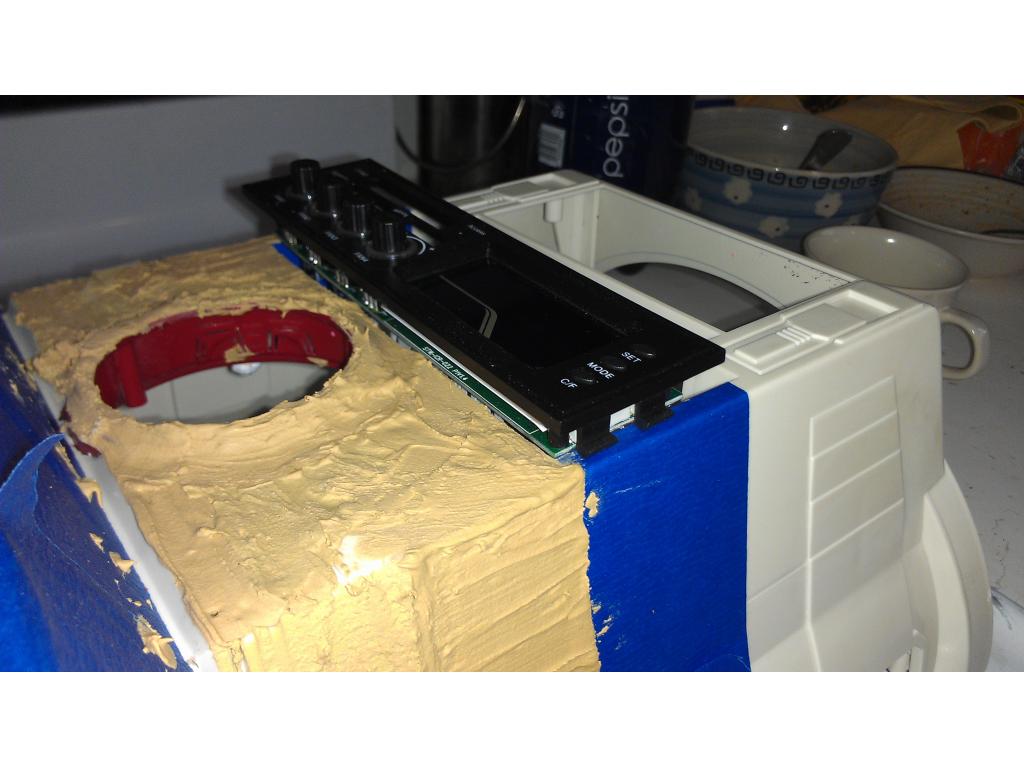
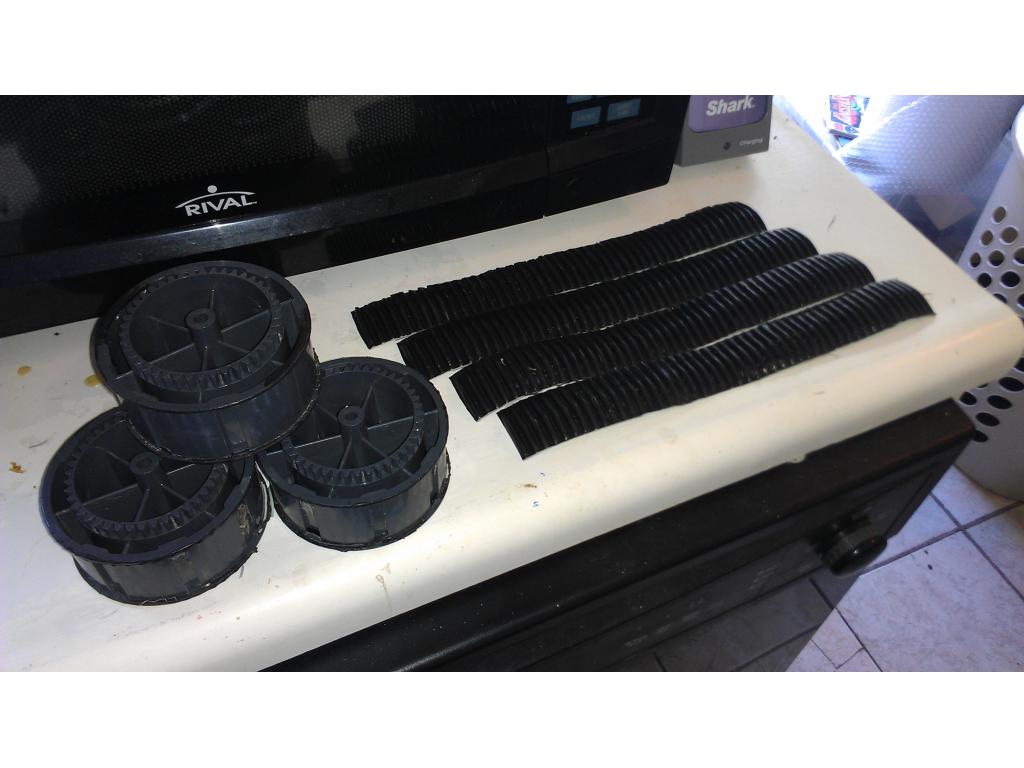
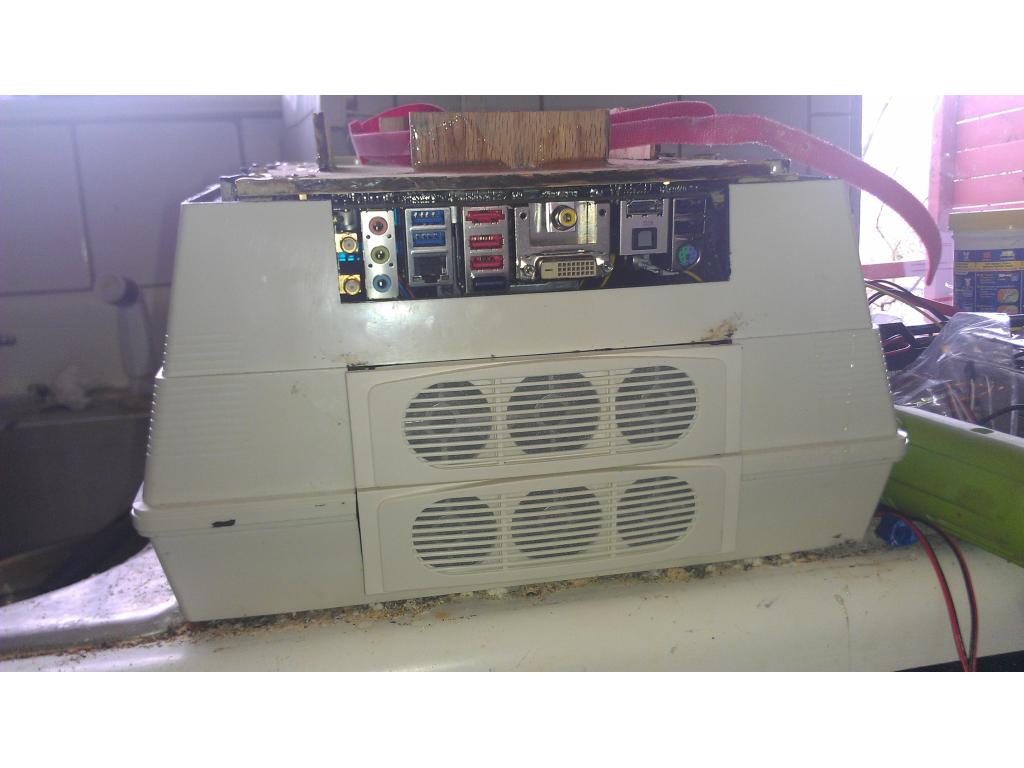
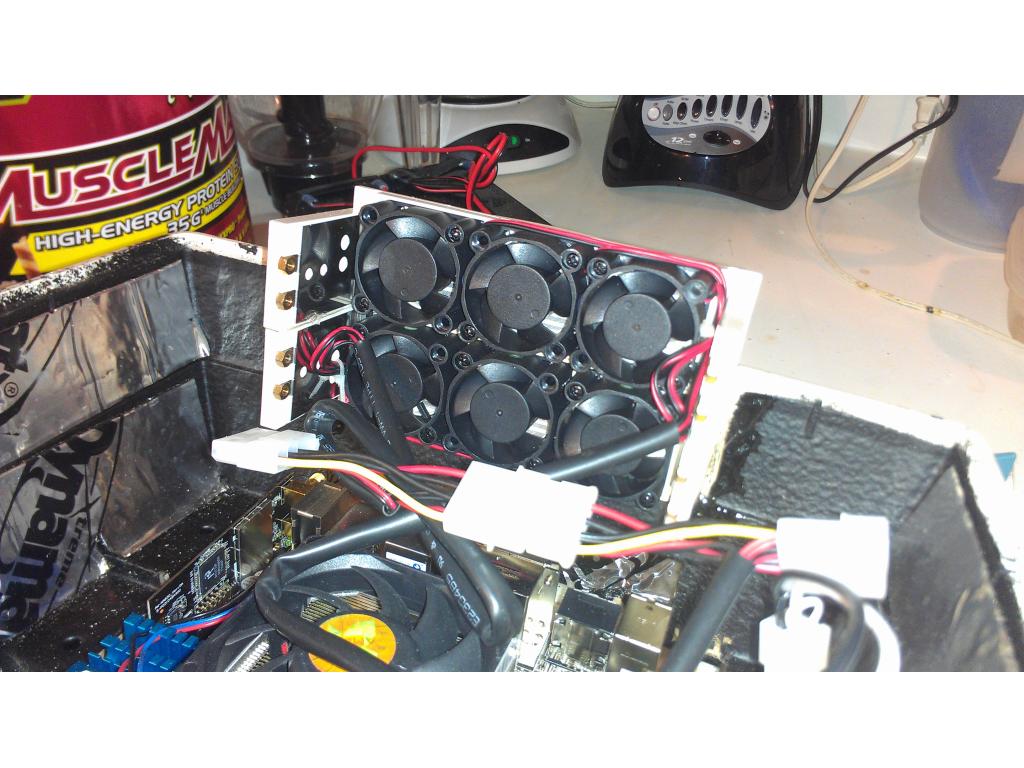
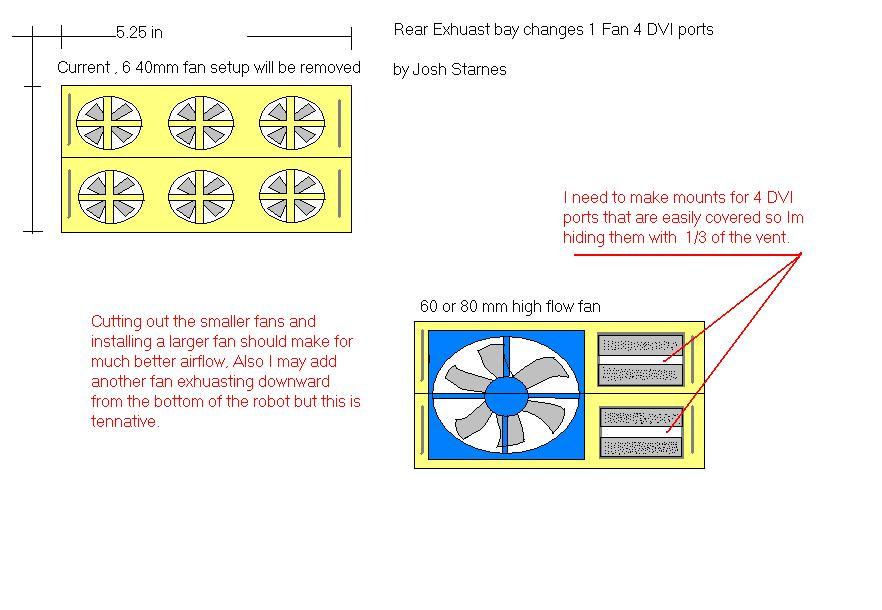
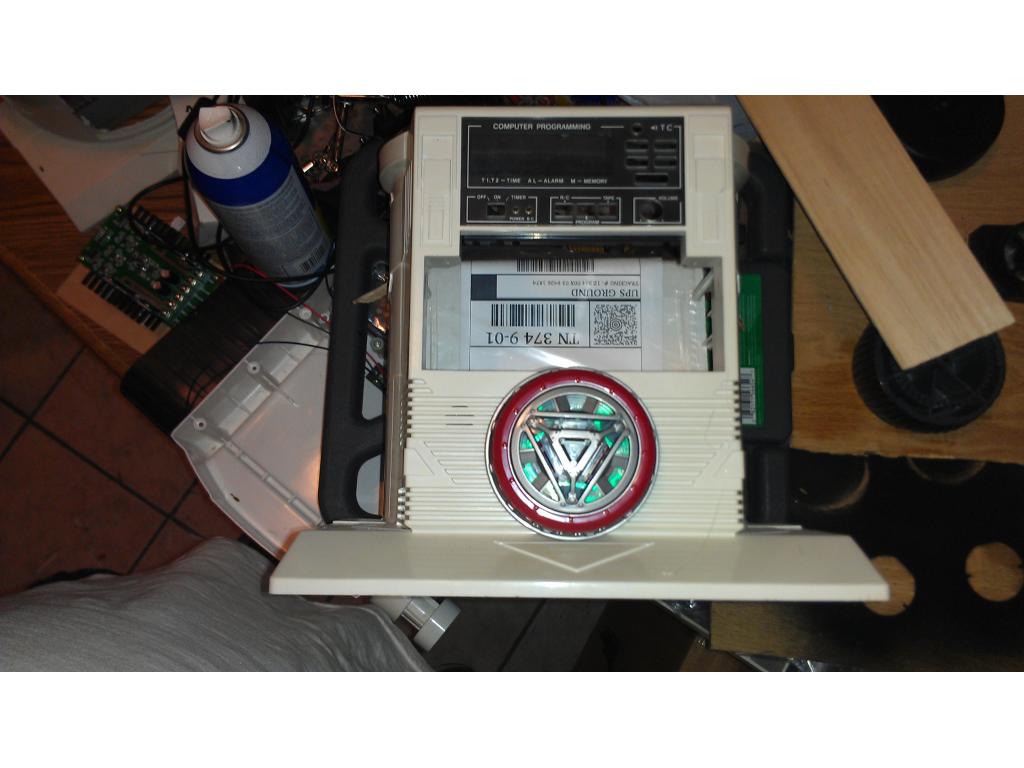
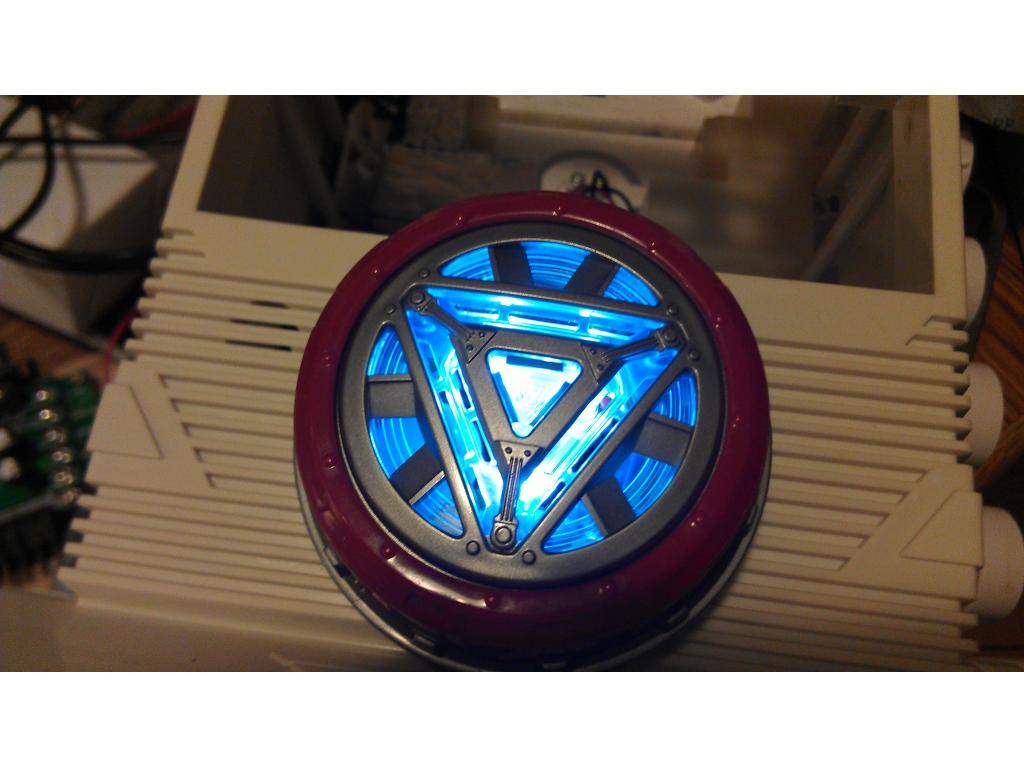
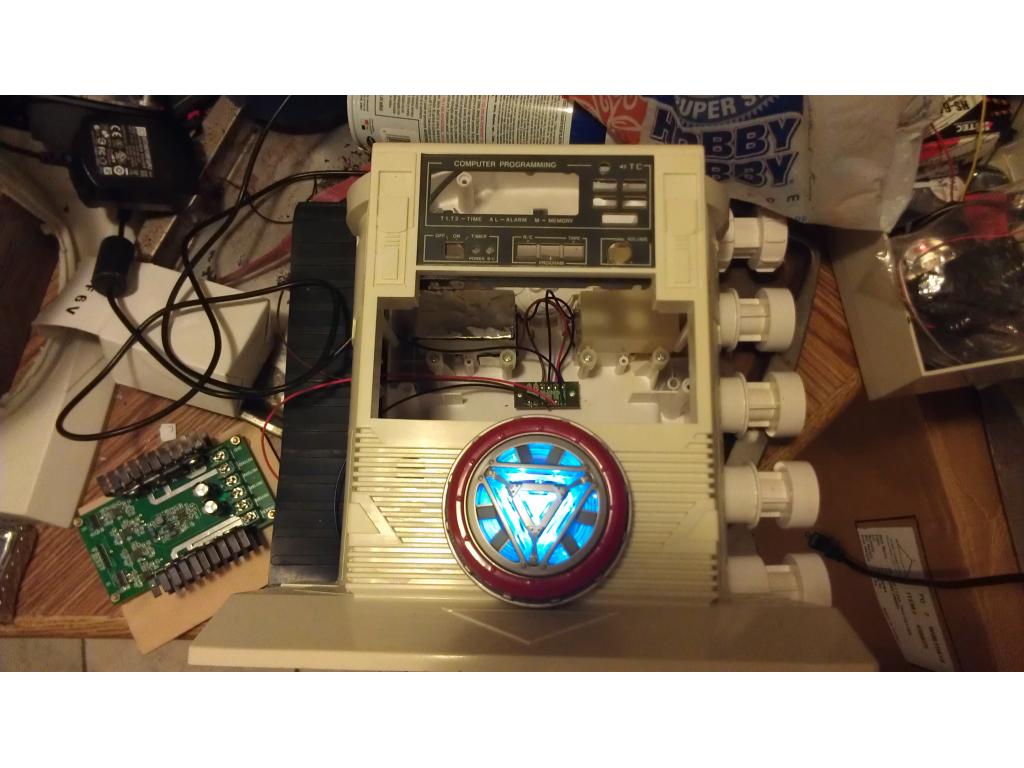
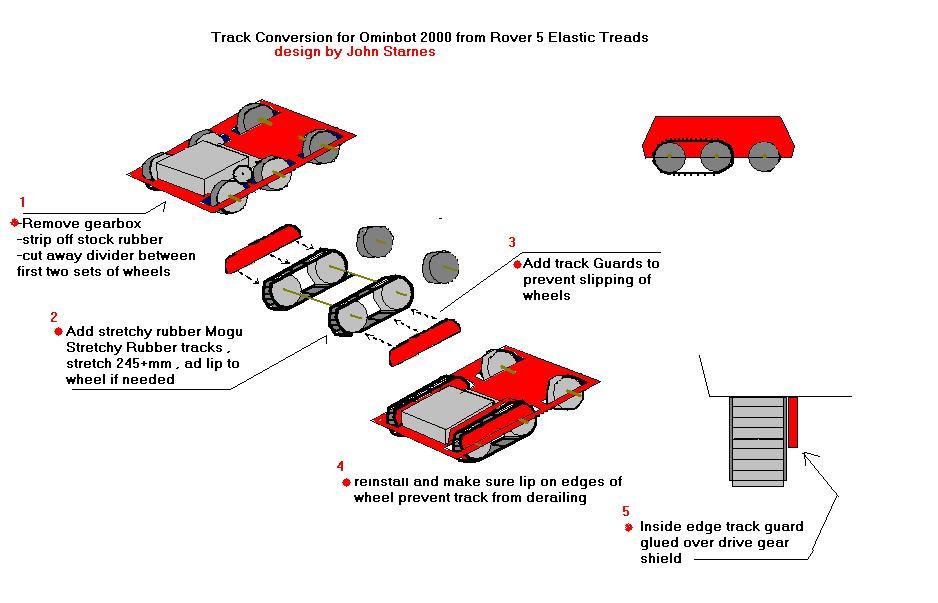
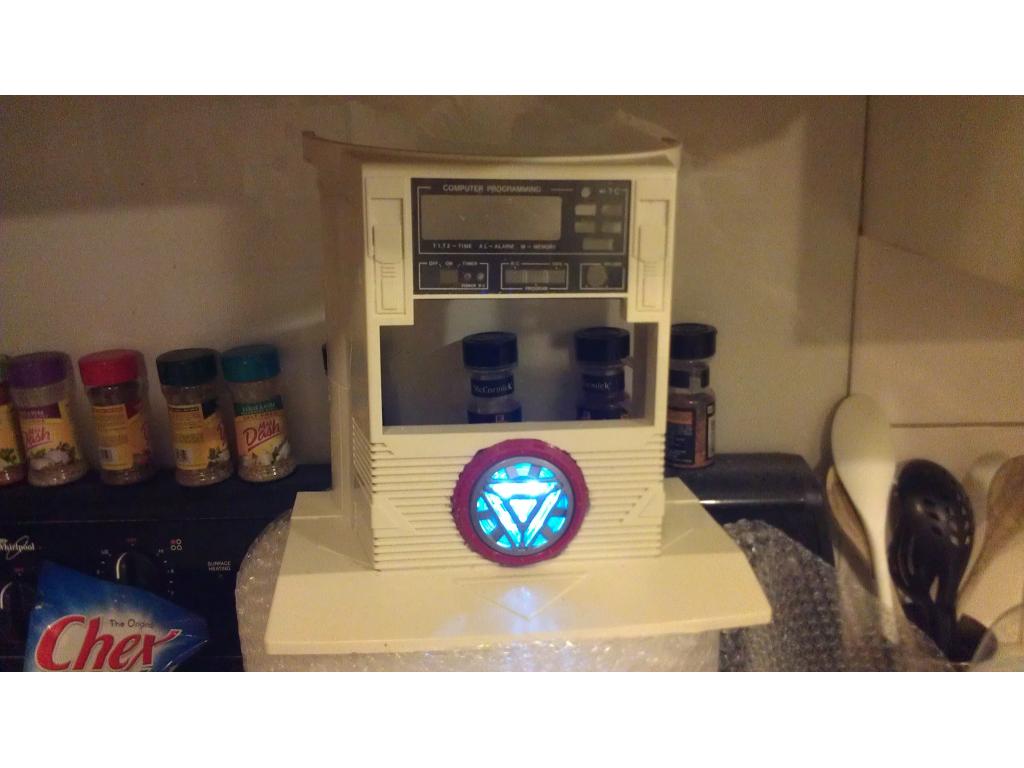
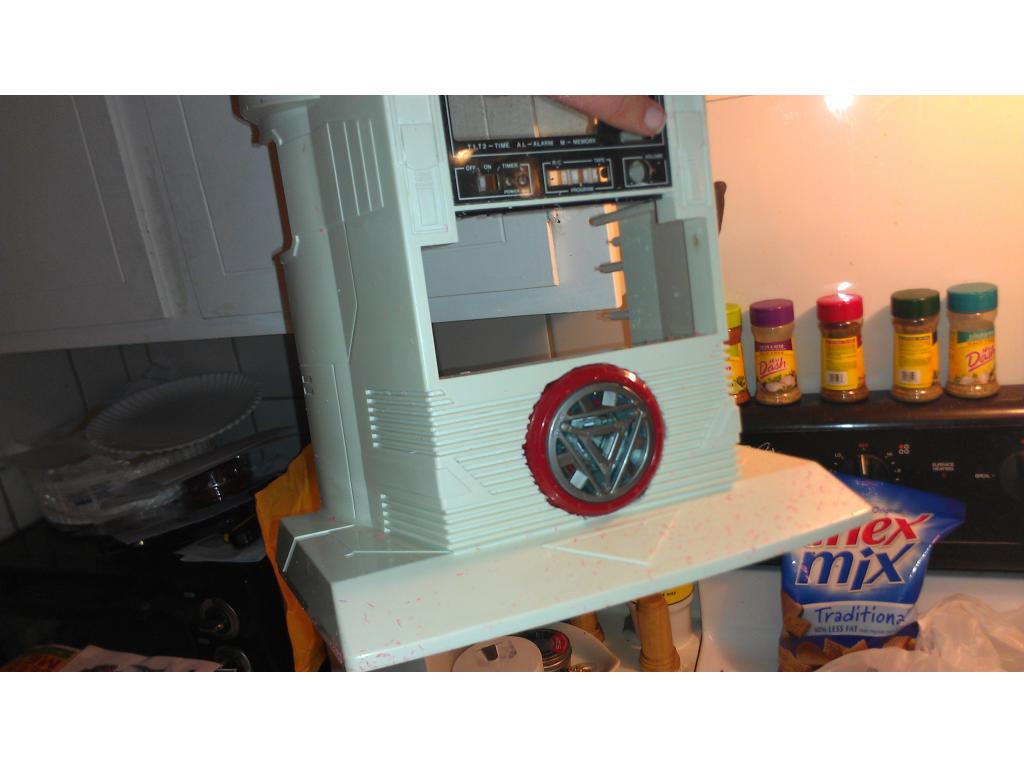
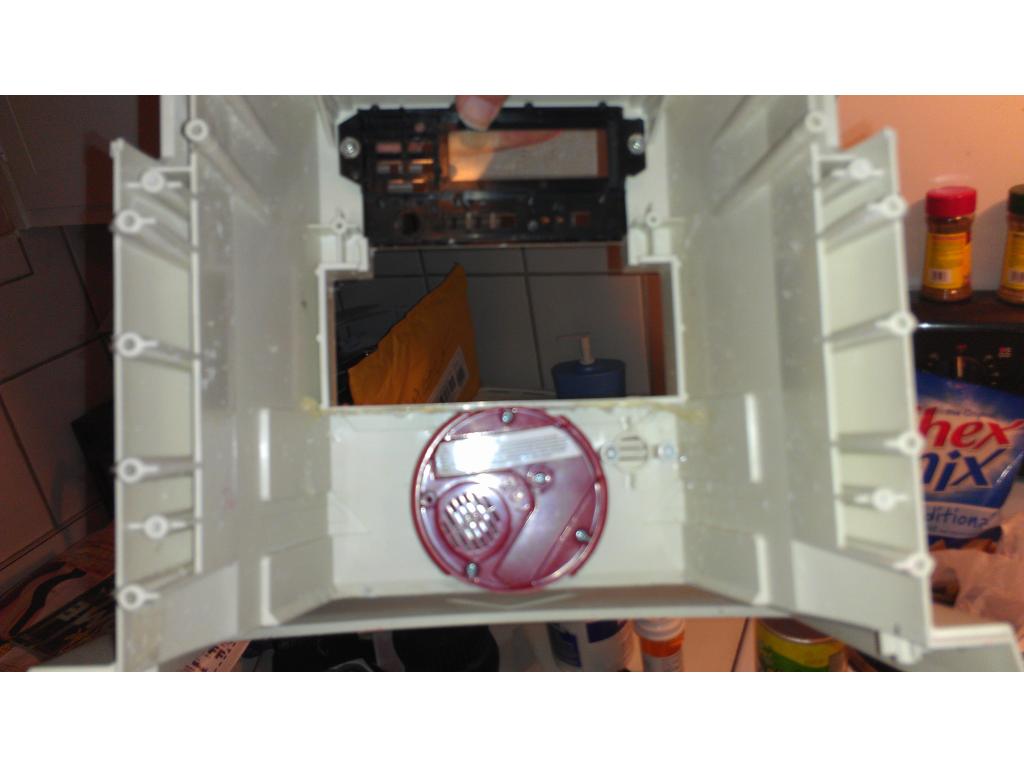
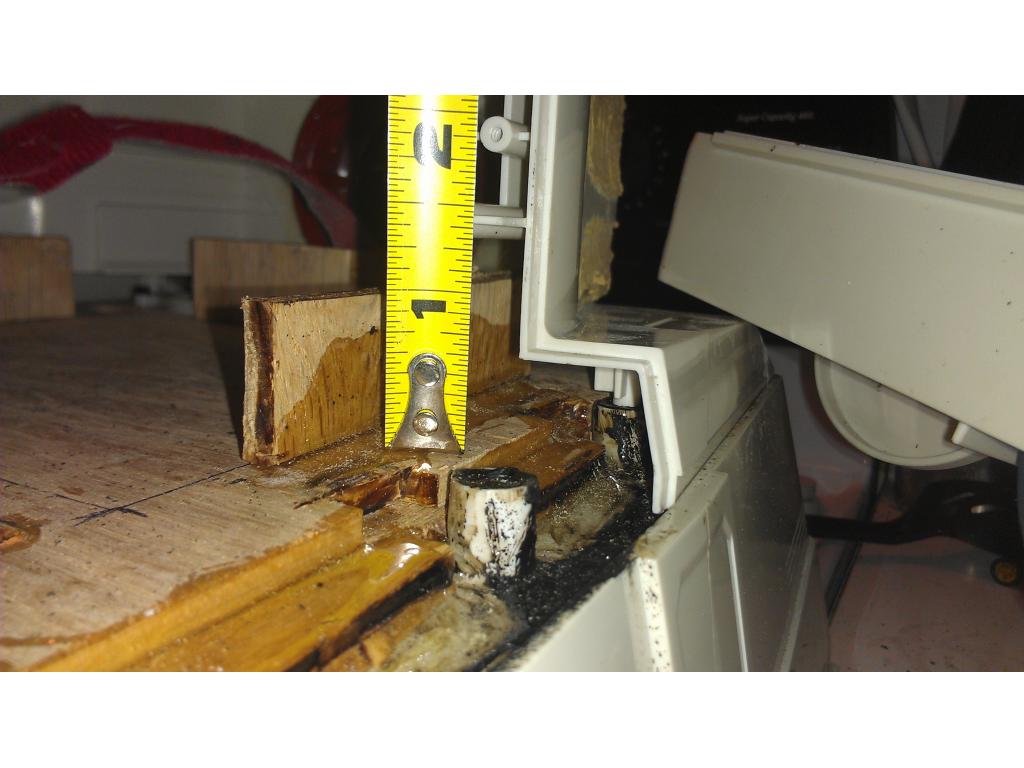
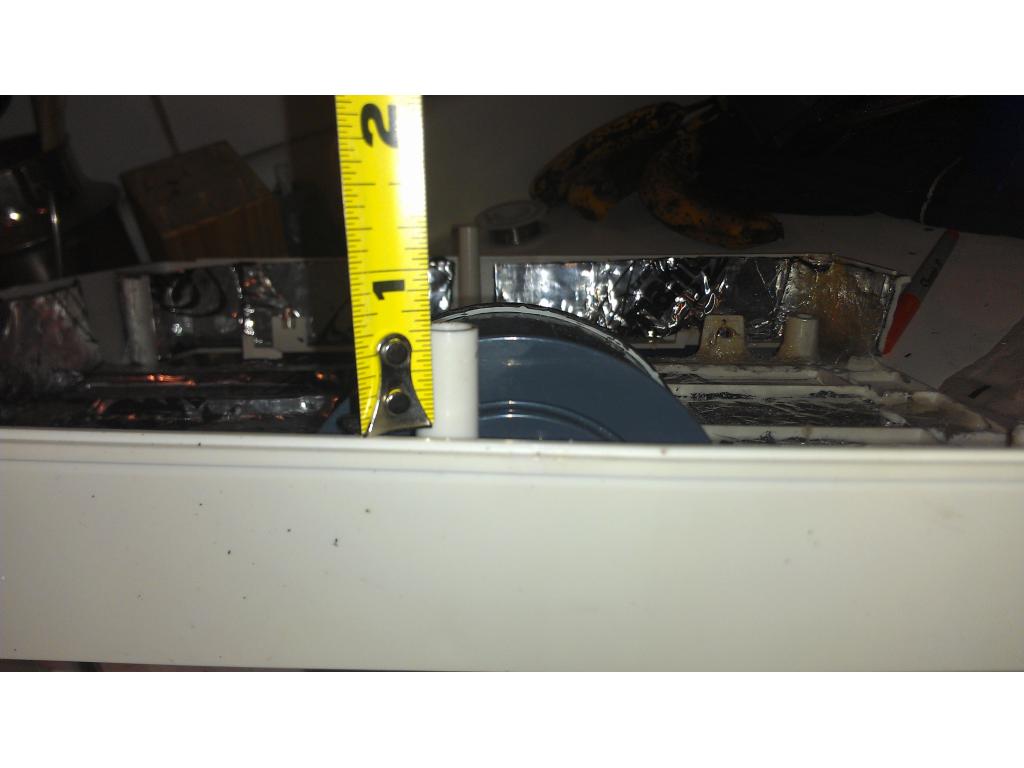
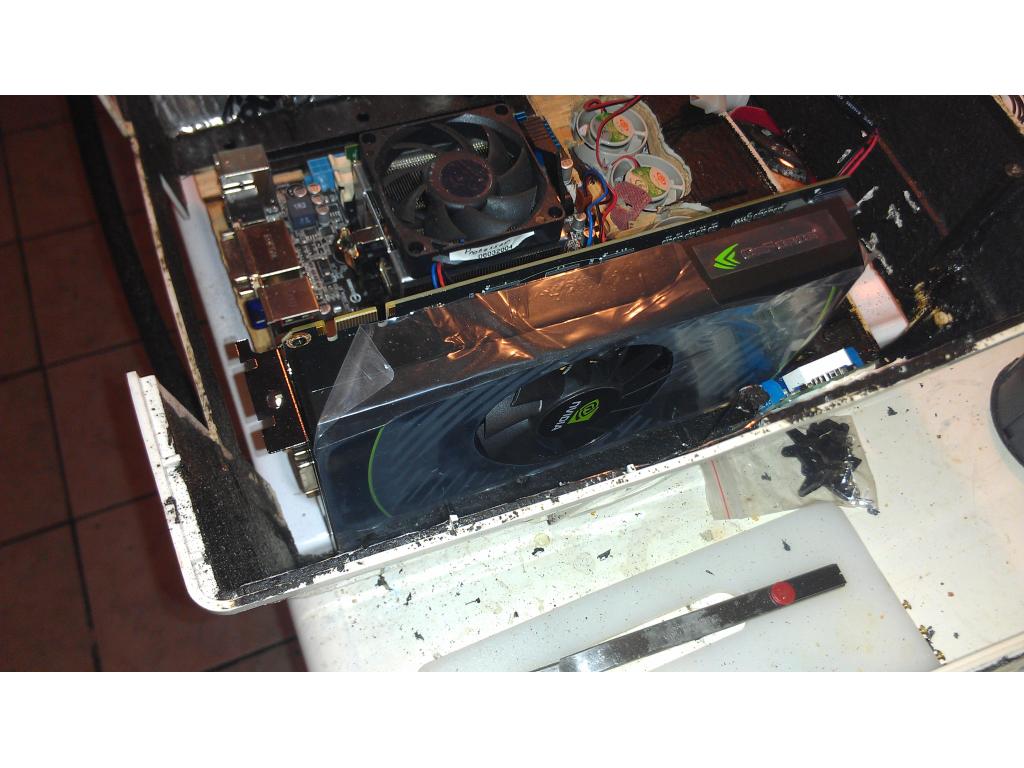
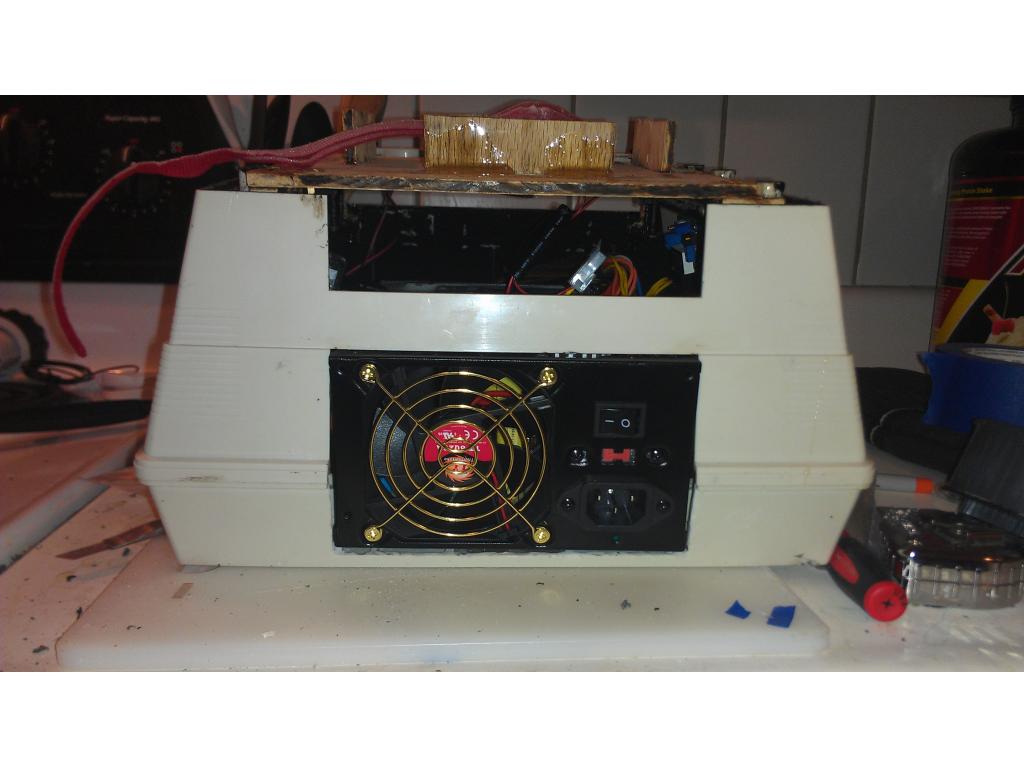
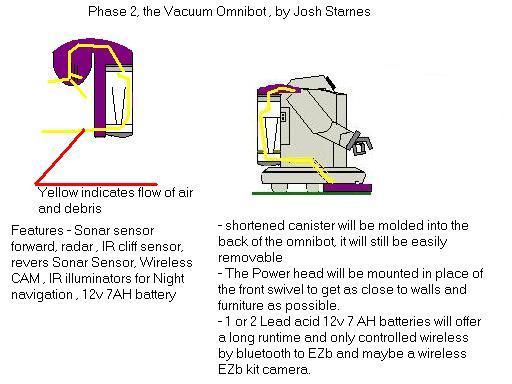
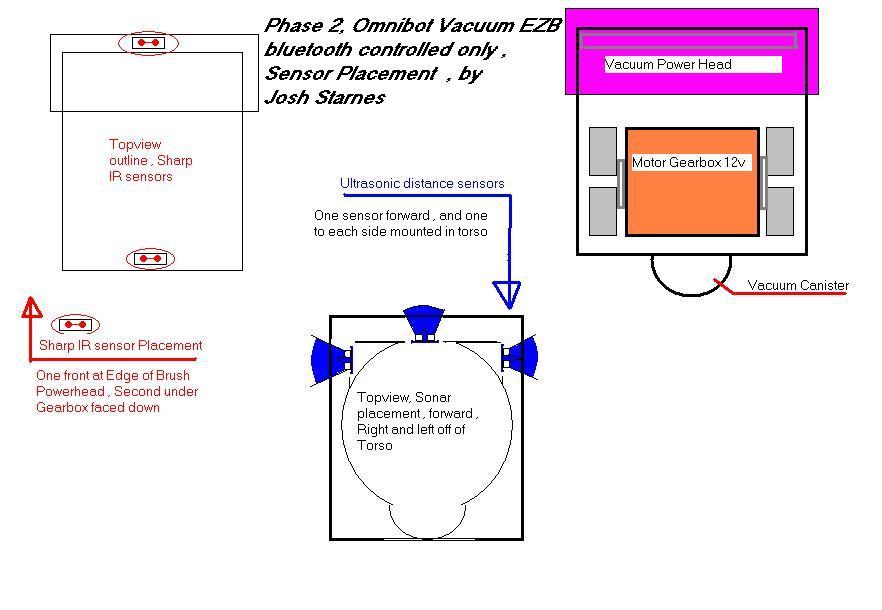
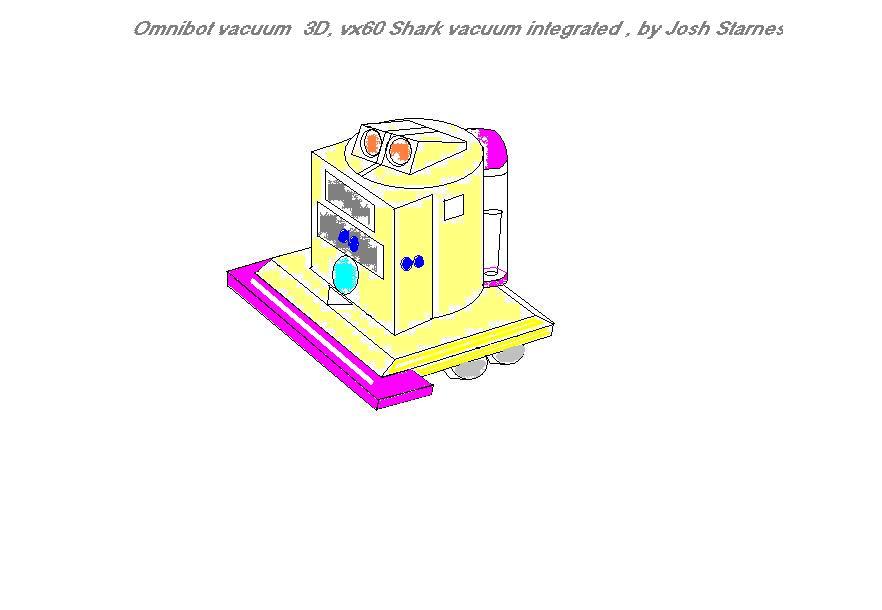
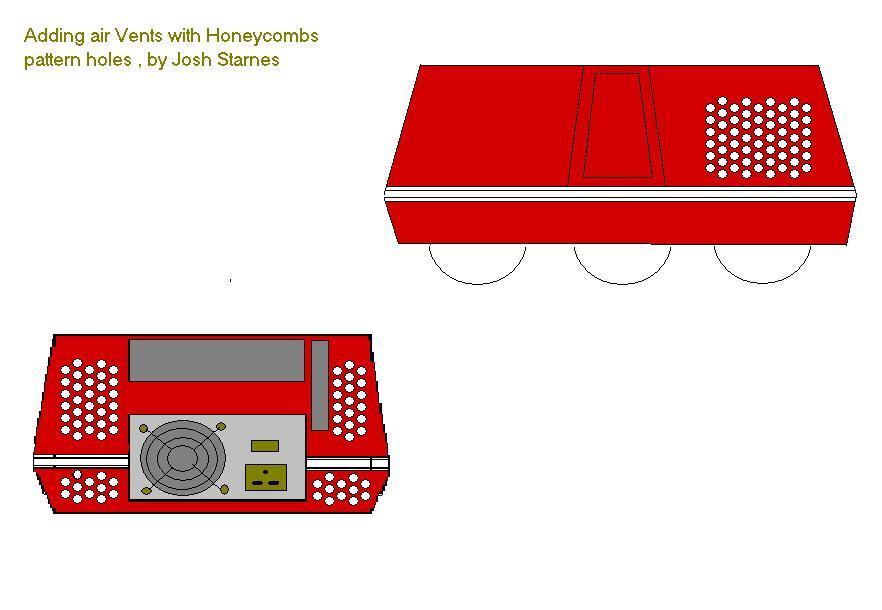
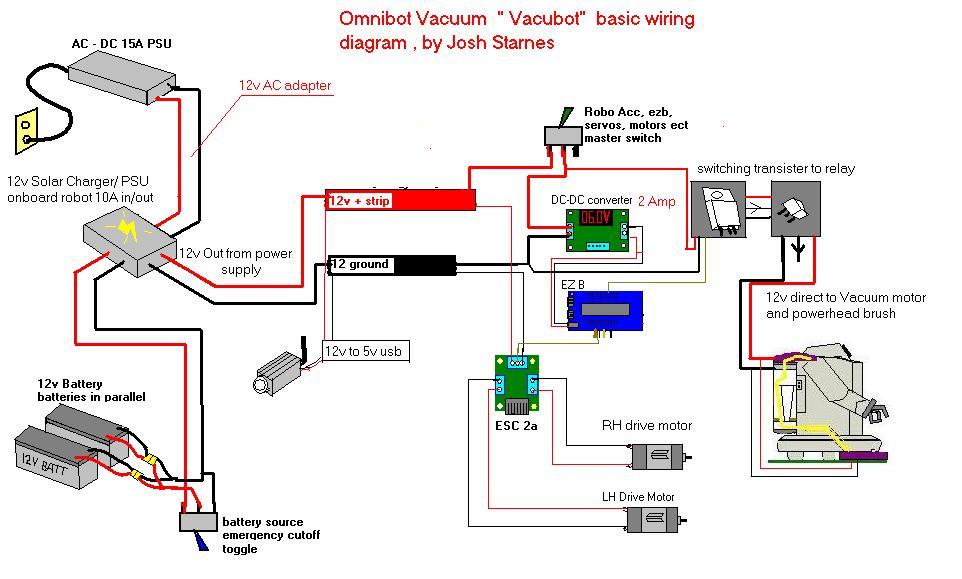
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.

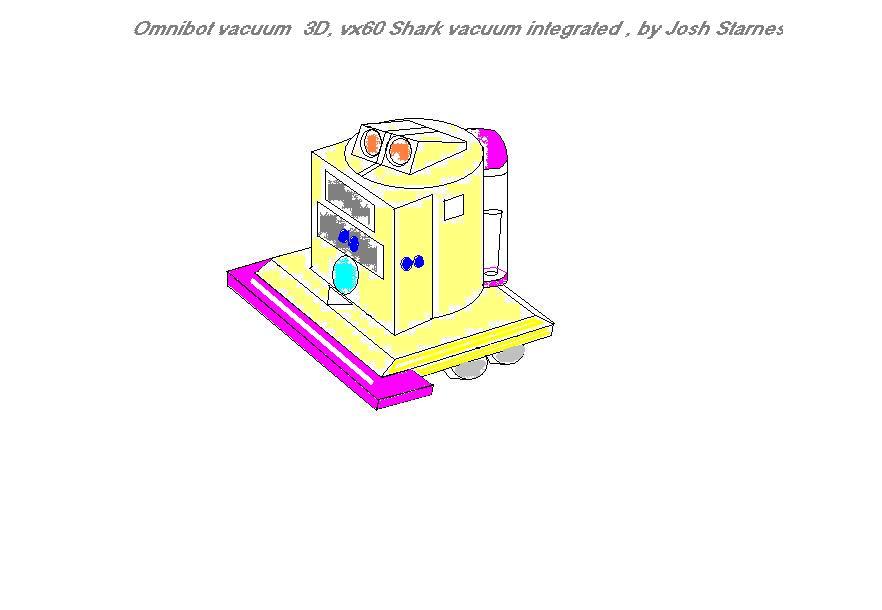
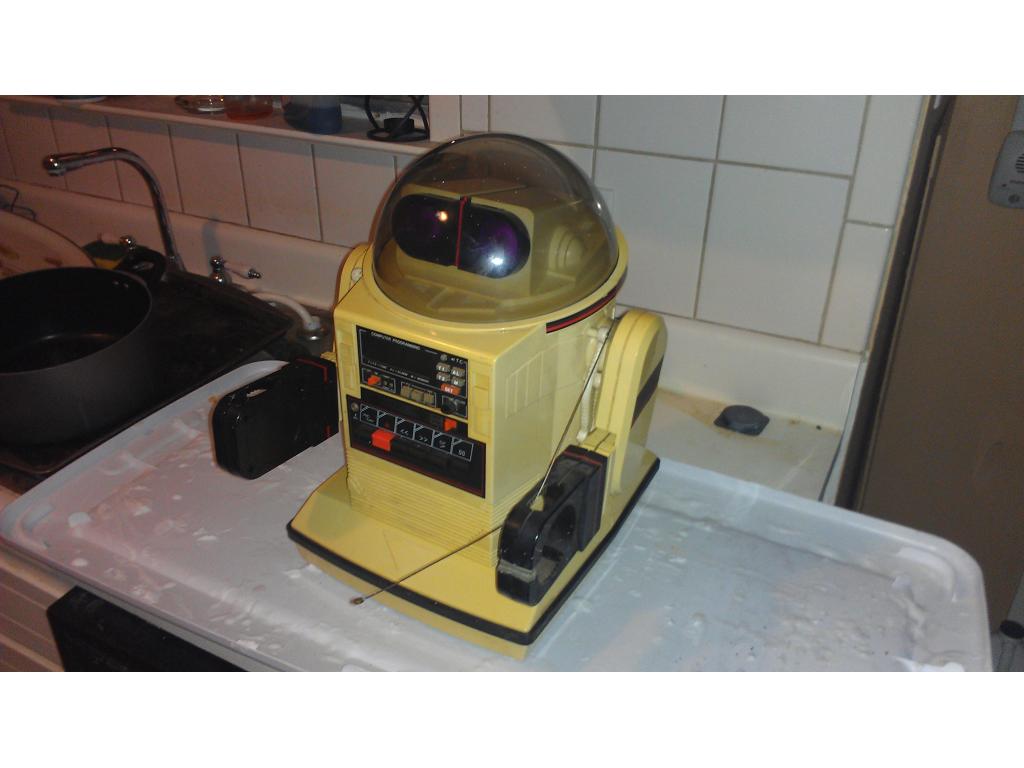
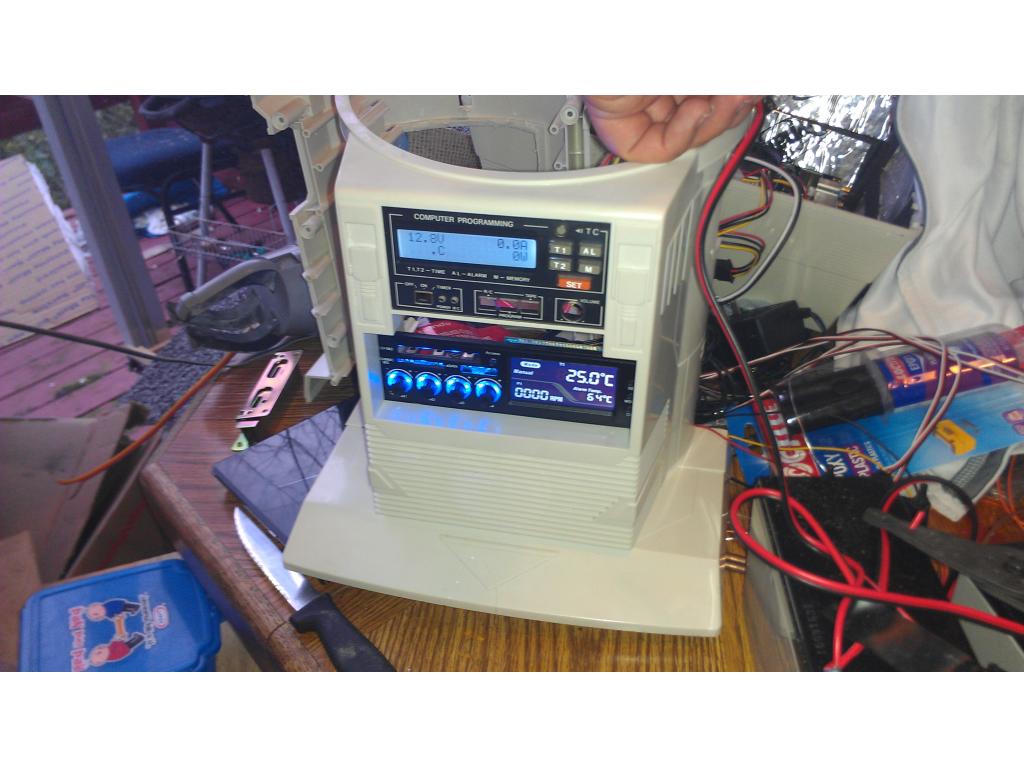
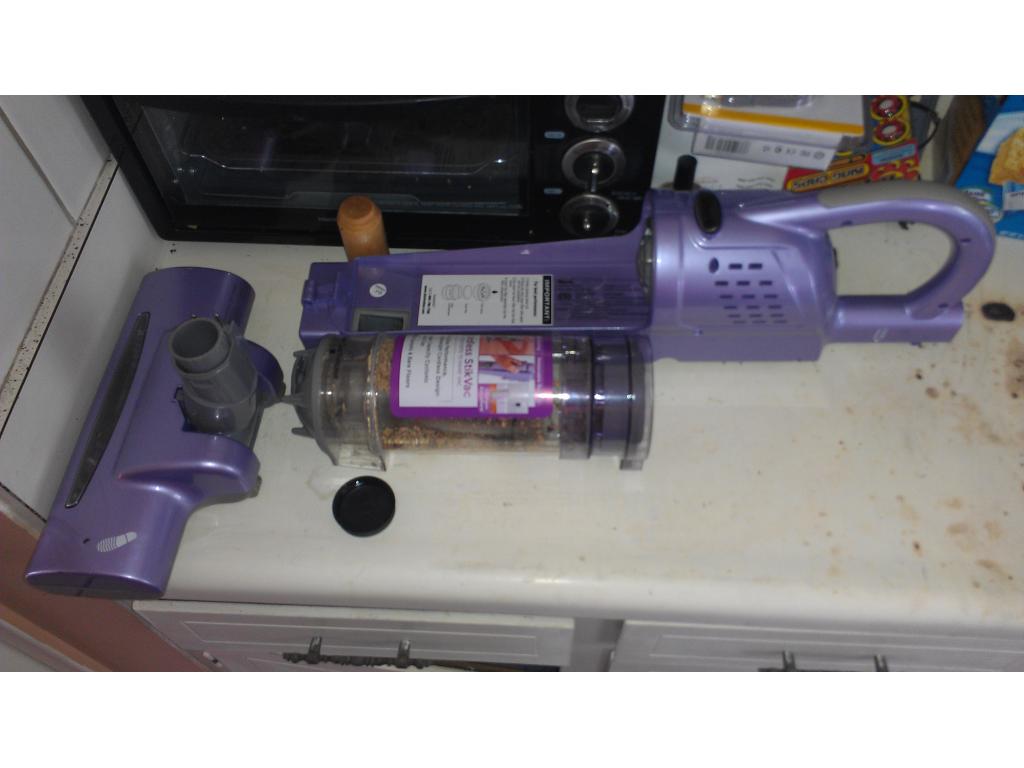
By jstarne1
— Last update

Discover more robots
Ezang's Let's Have Some JD Robot With Voice Commands
JD robot voice control with left-right head movement for natural, responsive interactions
Ezang's Happy Crawler 5/18/2021 And New Combination Robot...
Metal-legged robot built with Servo City parts and 4 servos, IoTiny battery, using Synthiam ARC programming to achieve...
Ezang's Beginning 3D Printed Hand, Some Moves - Voice...
New hand project needs rework with better string, other commands and tips pending; still many tasks and development work...

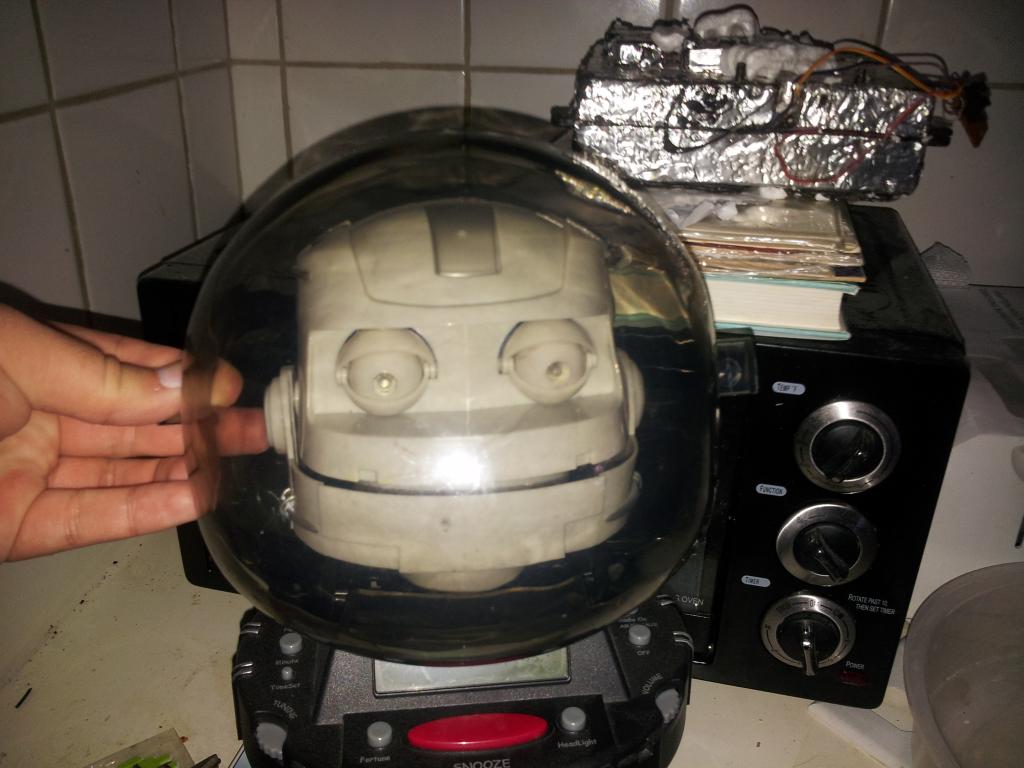
Video update- Jarvis neck moves for the first time.
https://www.youtube.com/watch?v=XYqal8AuqfA&feature=youtube_gdata_player
Good work, Josh!
Looks sweet!
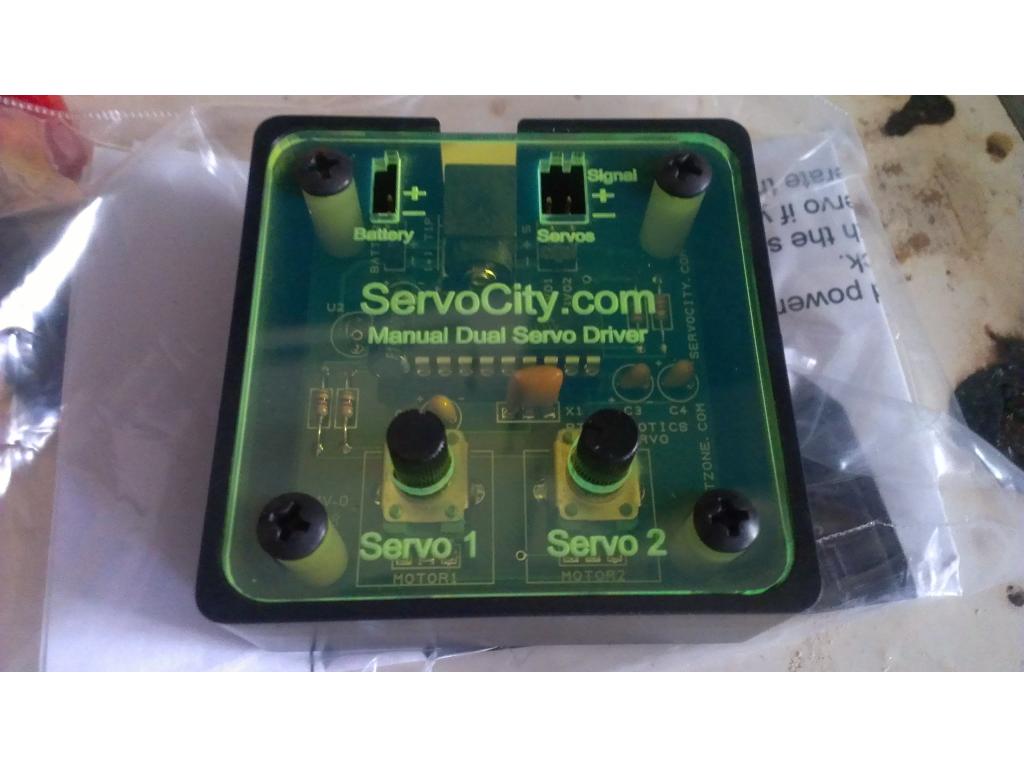
I only had 2 of the three servos powered up so one sorta tilted to the side. I must test the arms soon and I will use the same servo signal generator. Holding position the robots servos had a very light buzzing noise that's barely audible.
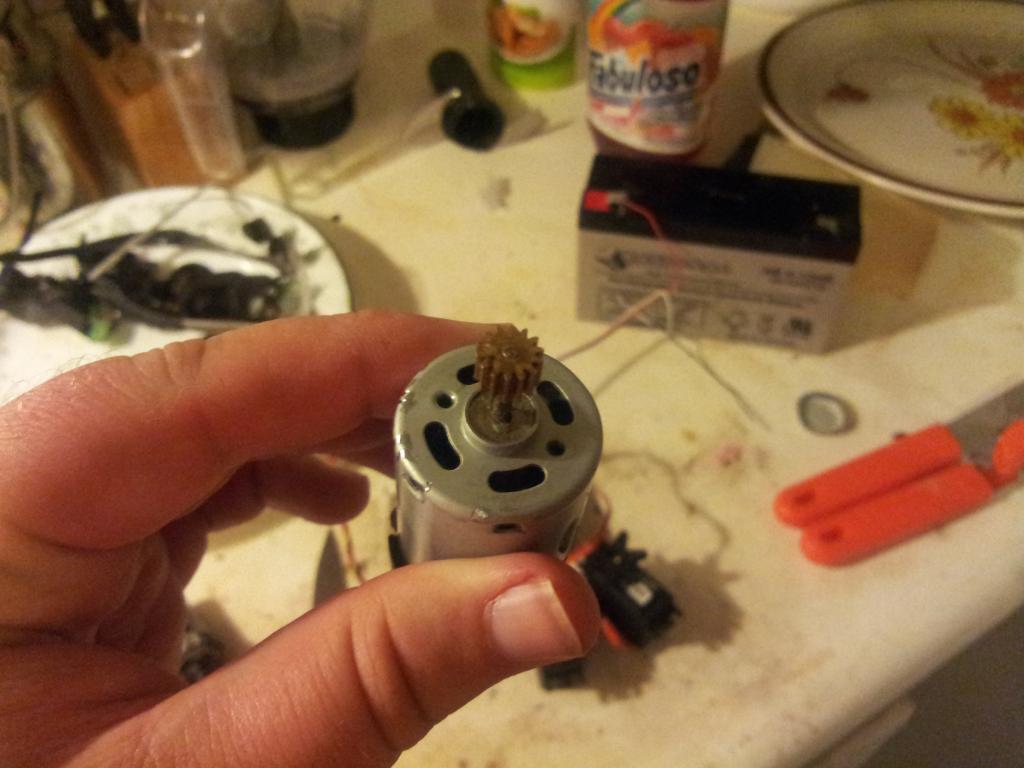
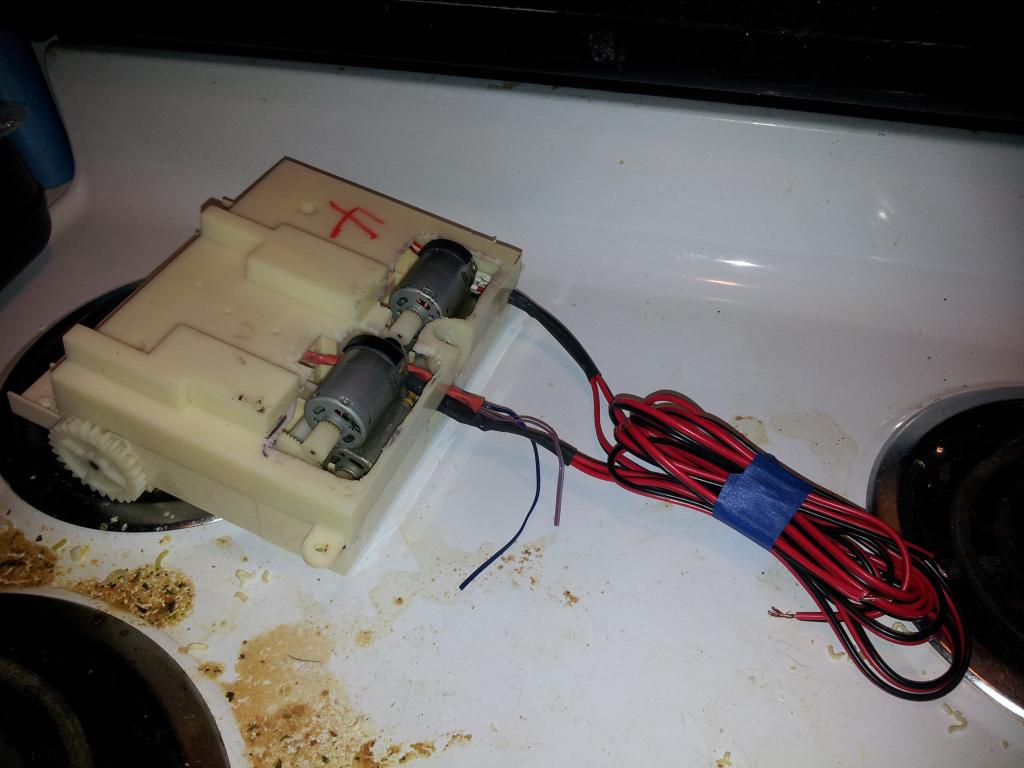
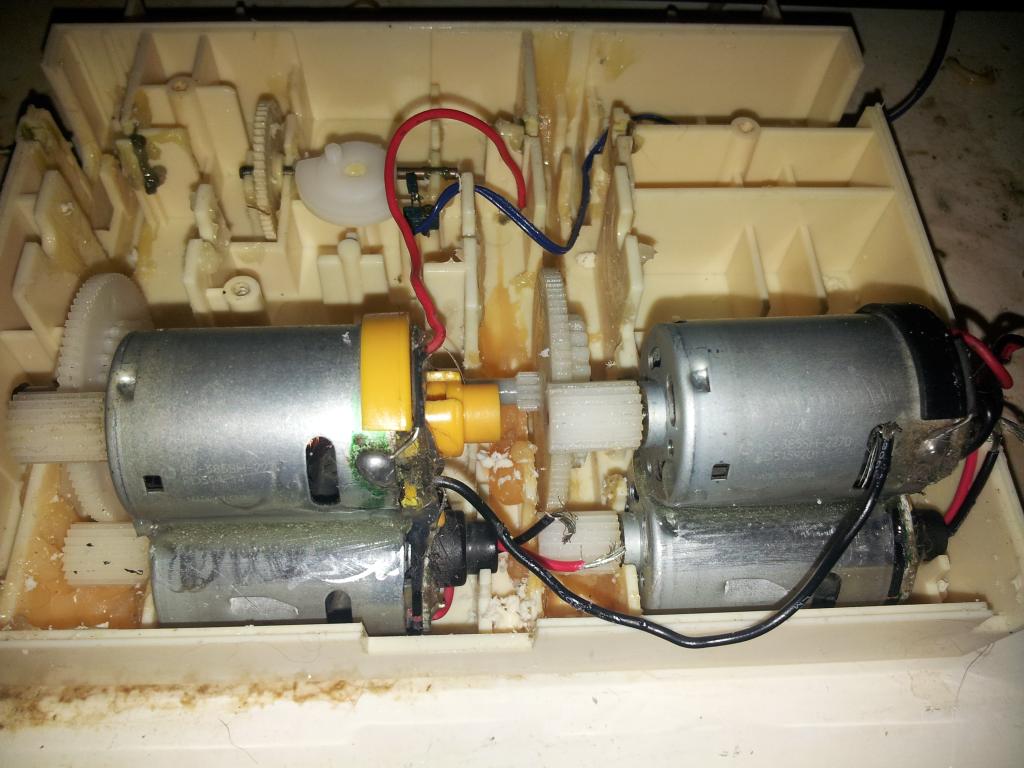
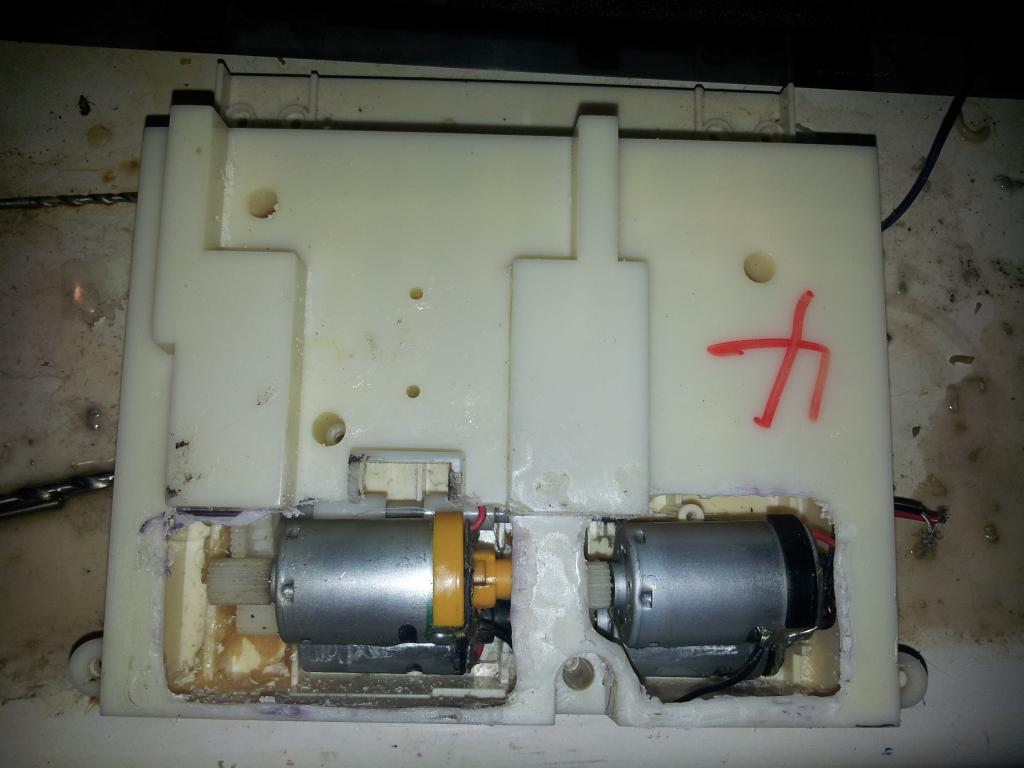
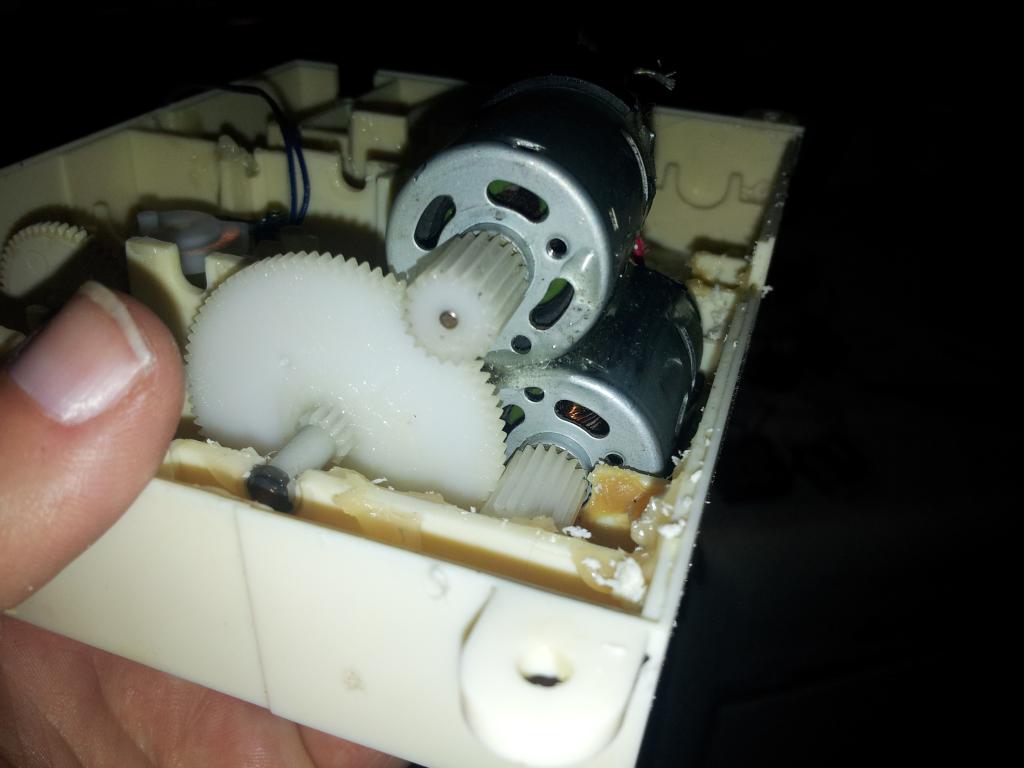
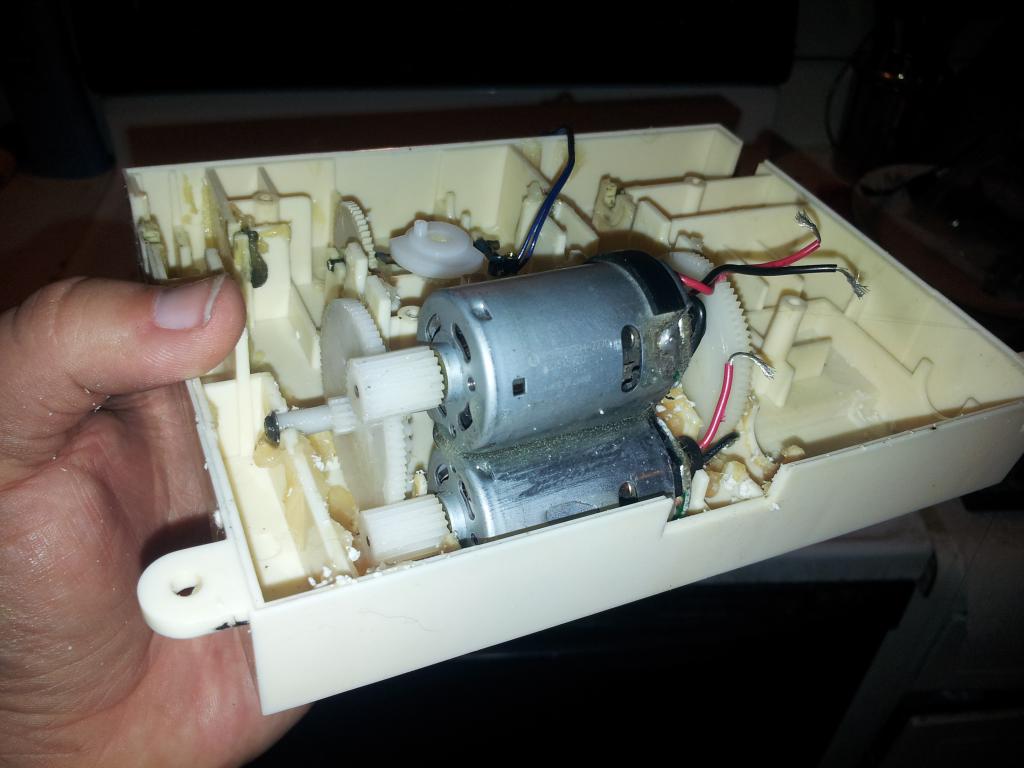
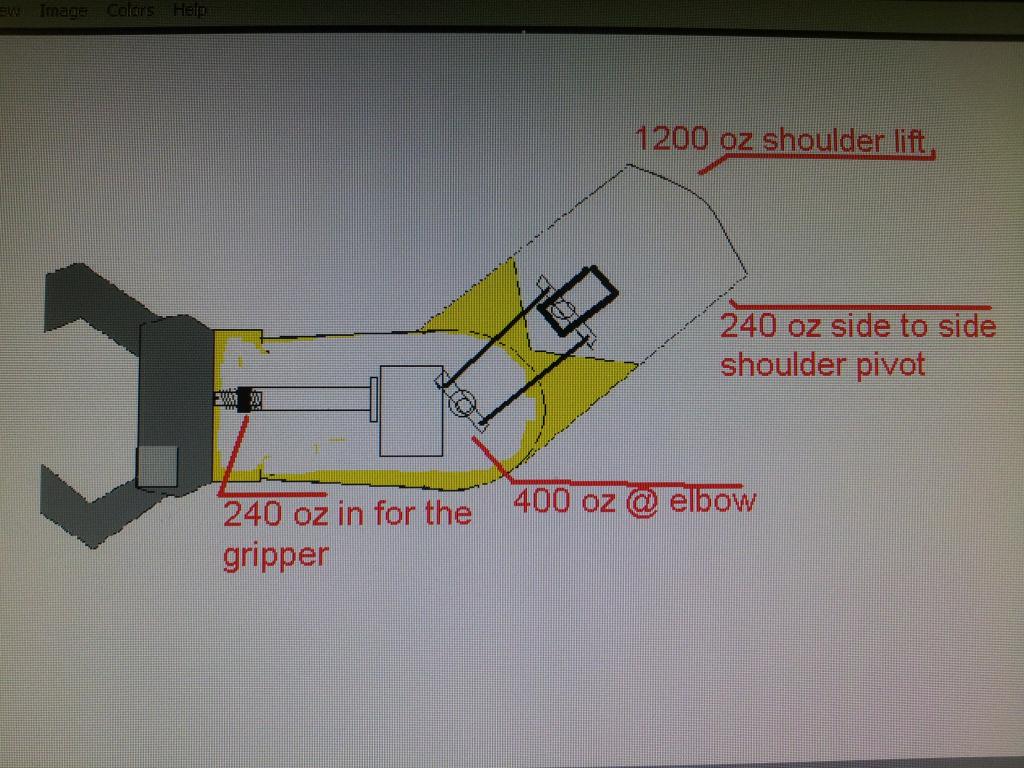
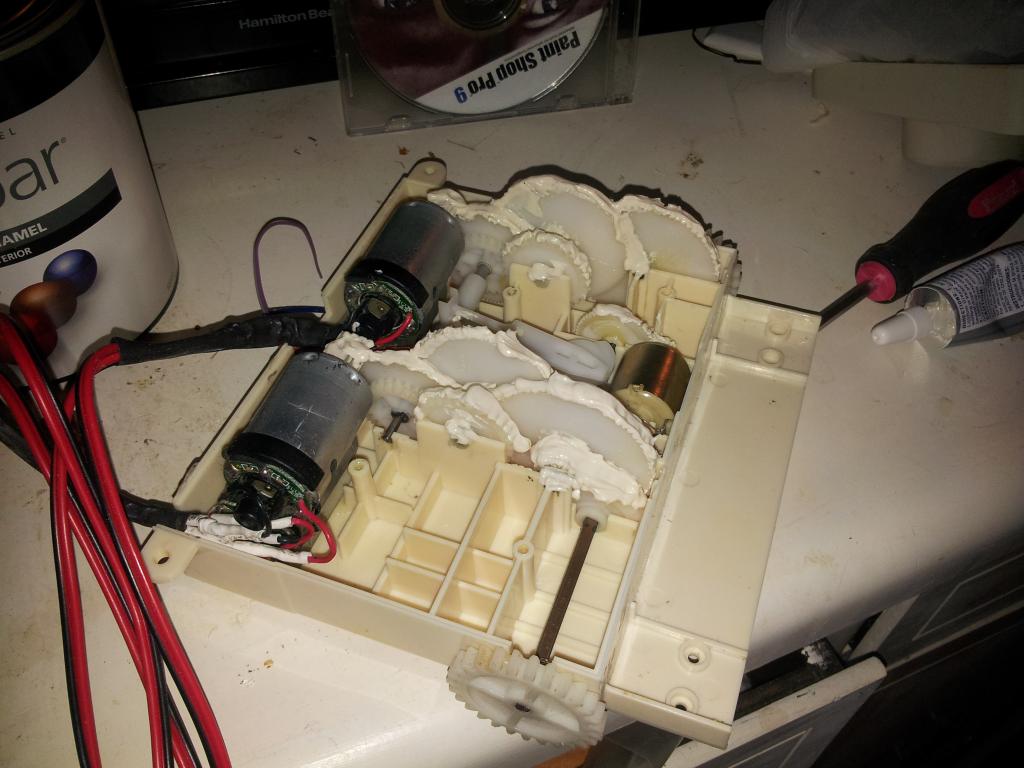
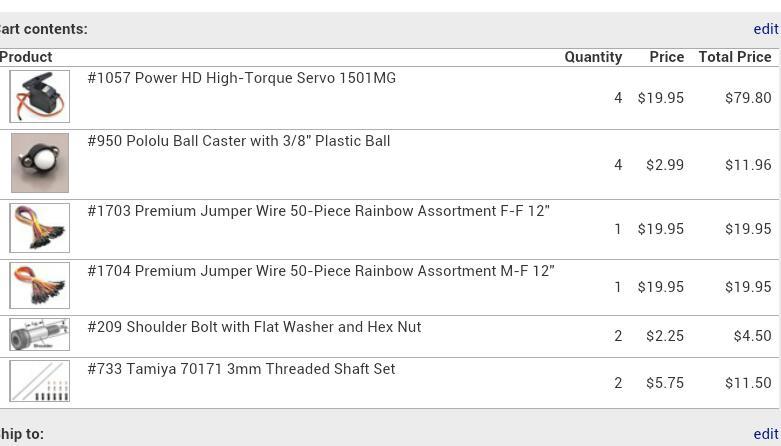
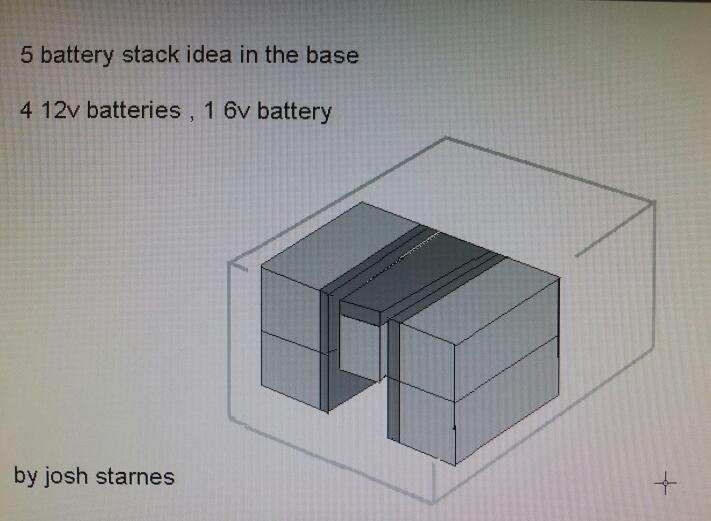
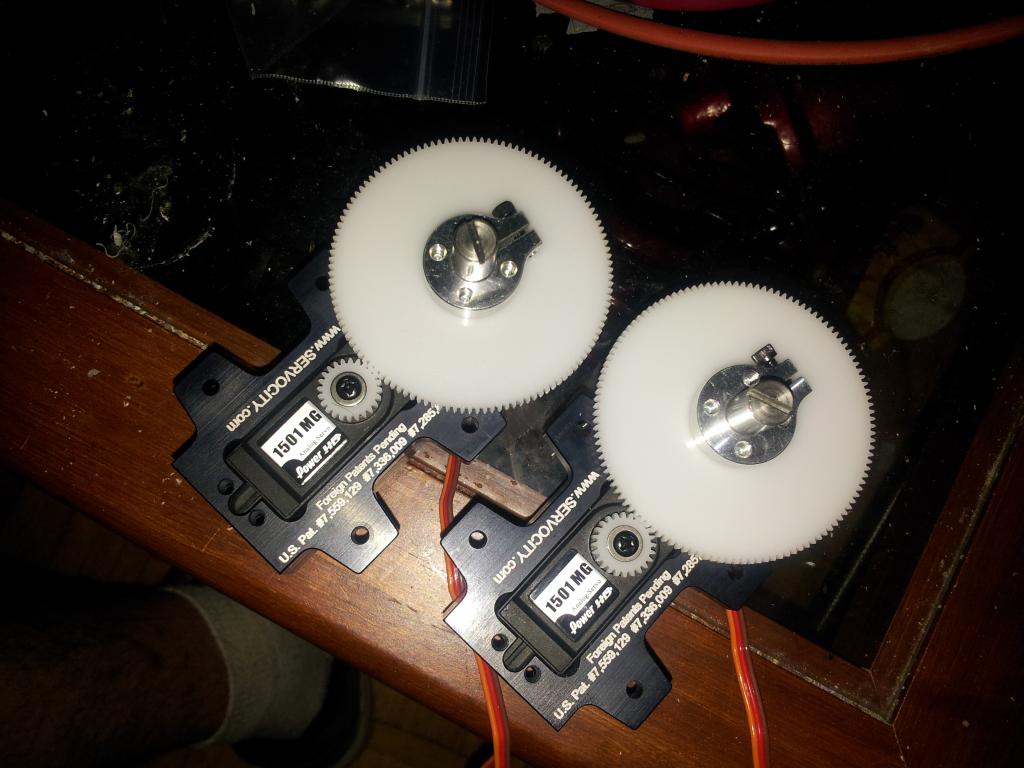
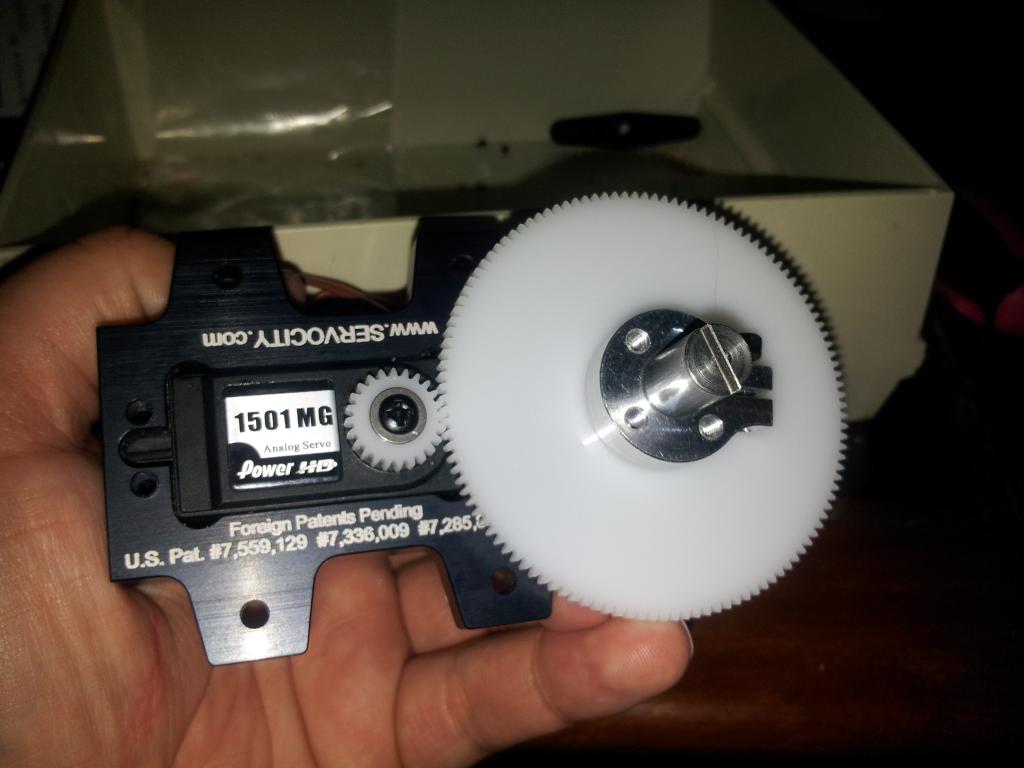
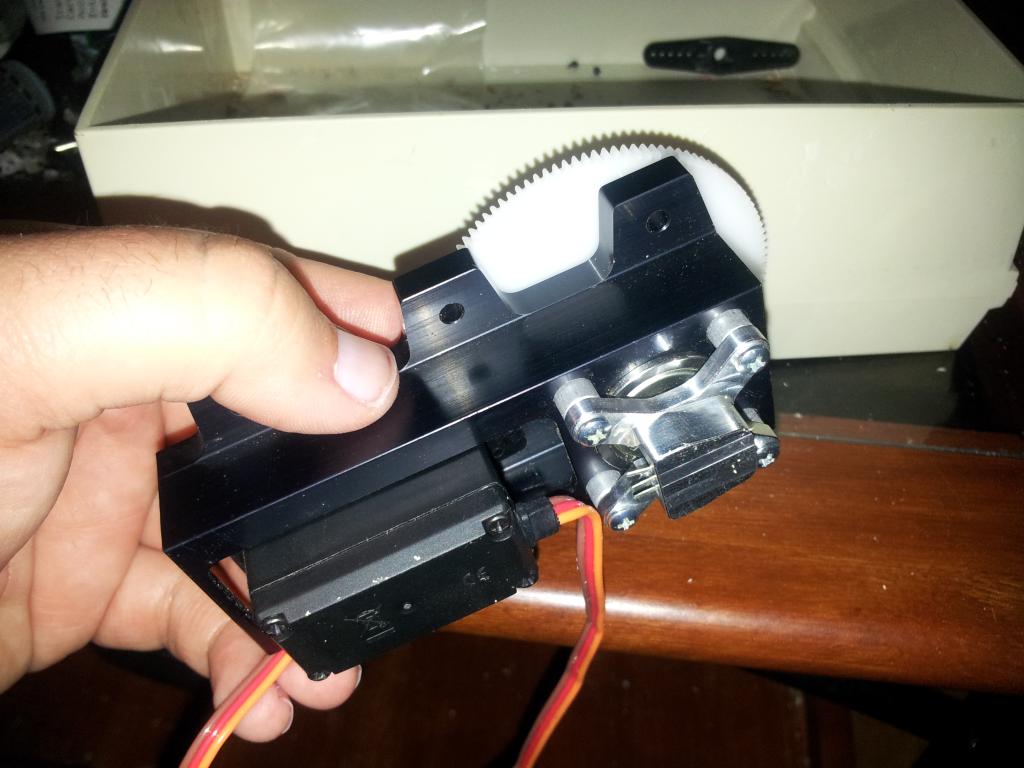
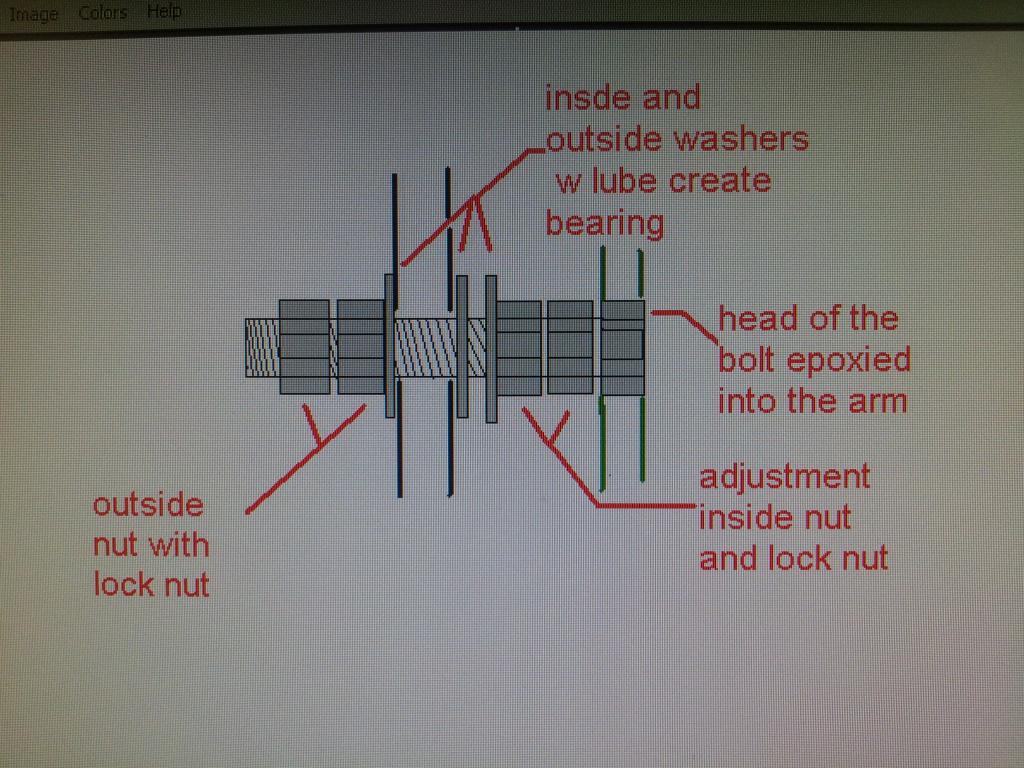
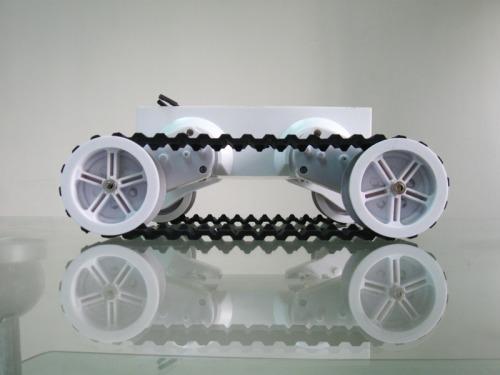
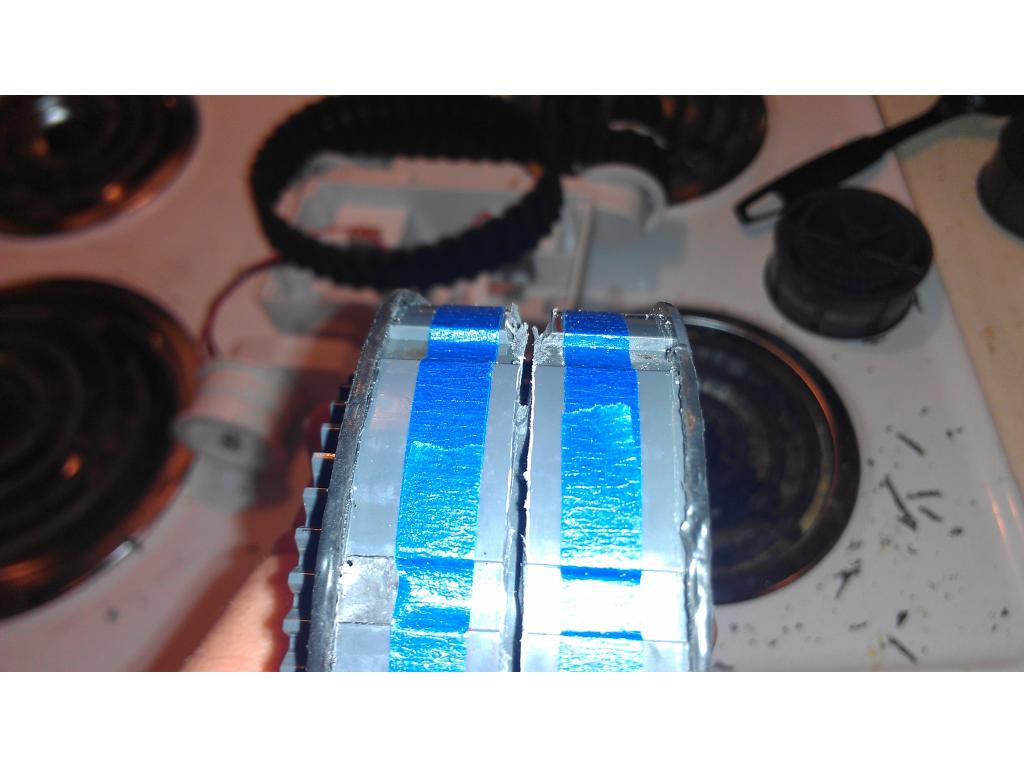
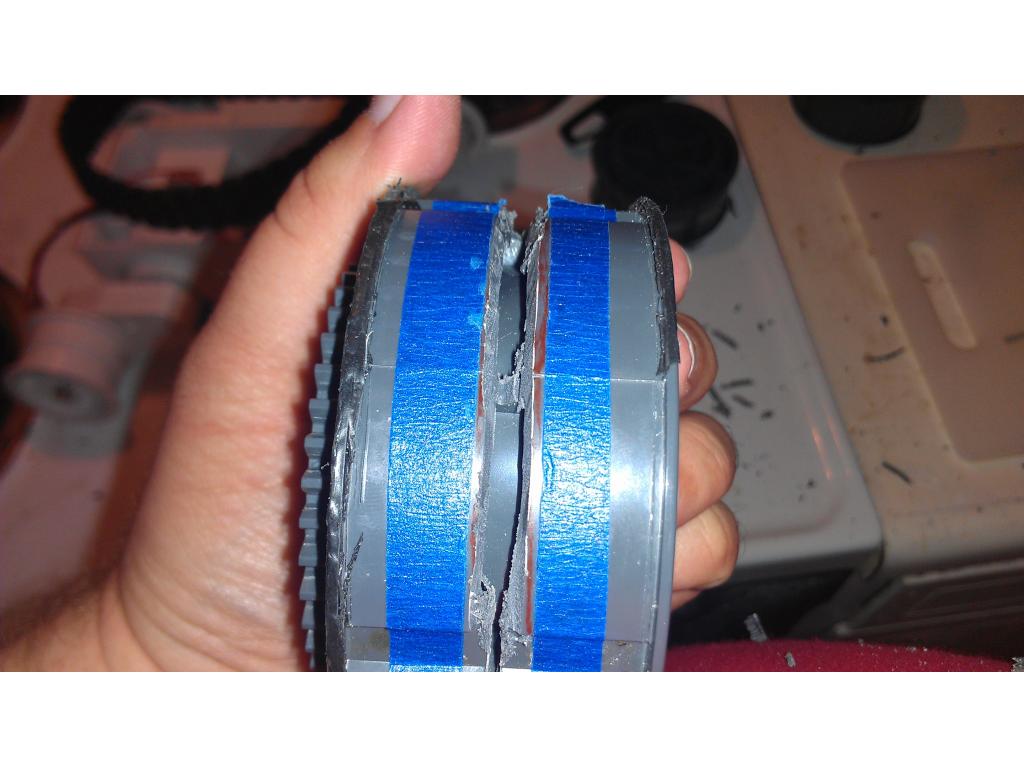
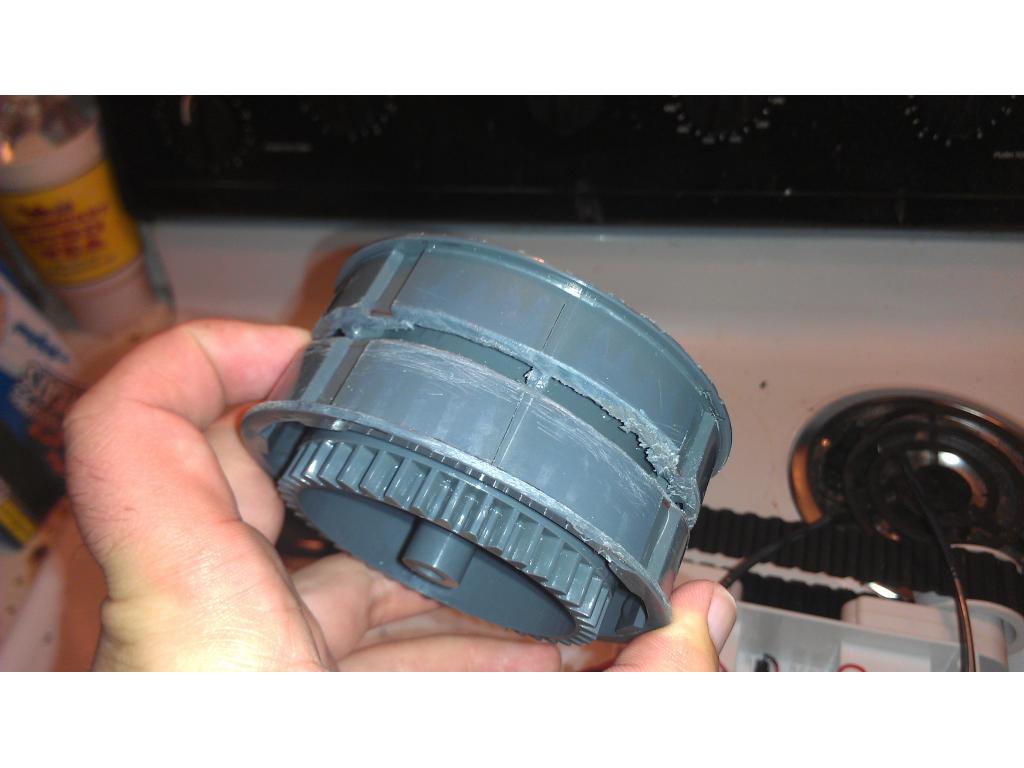
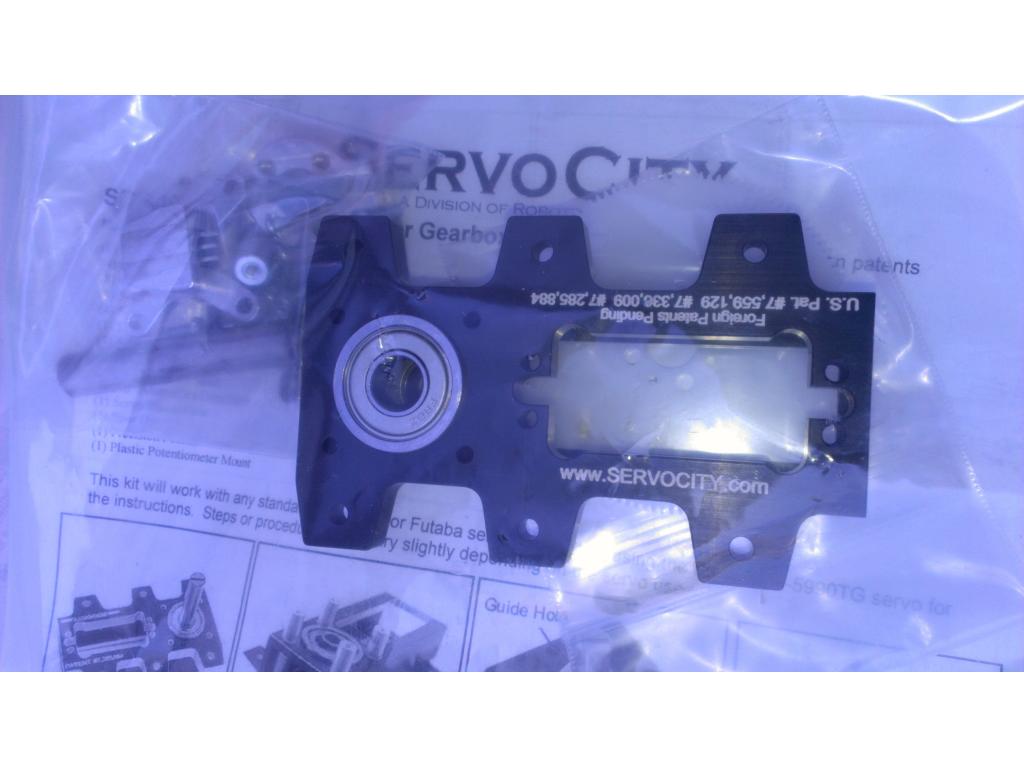
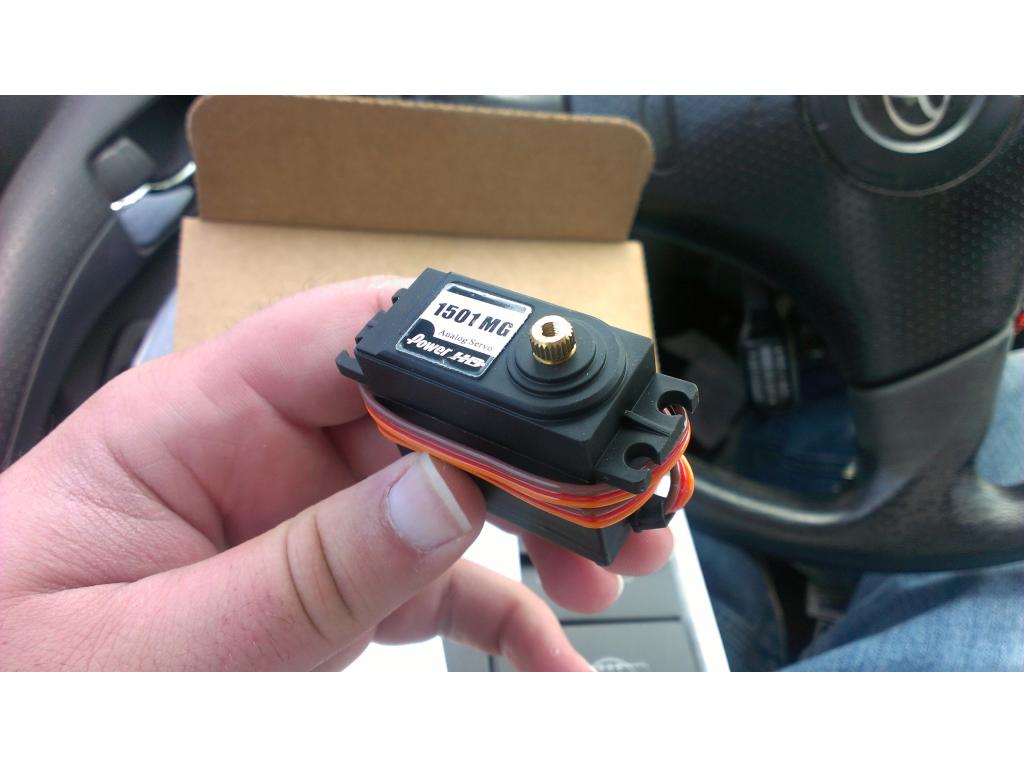
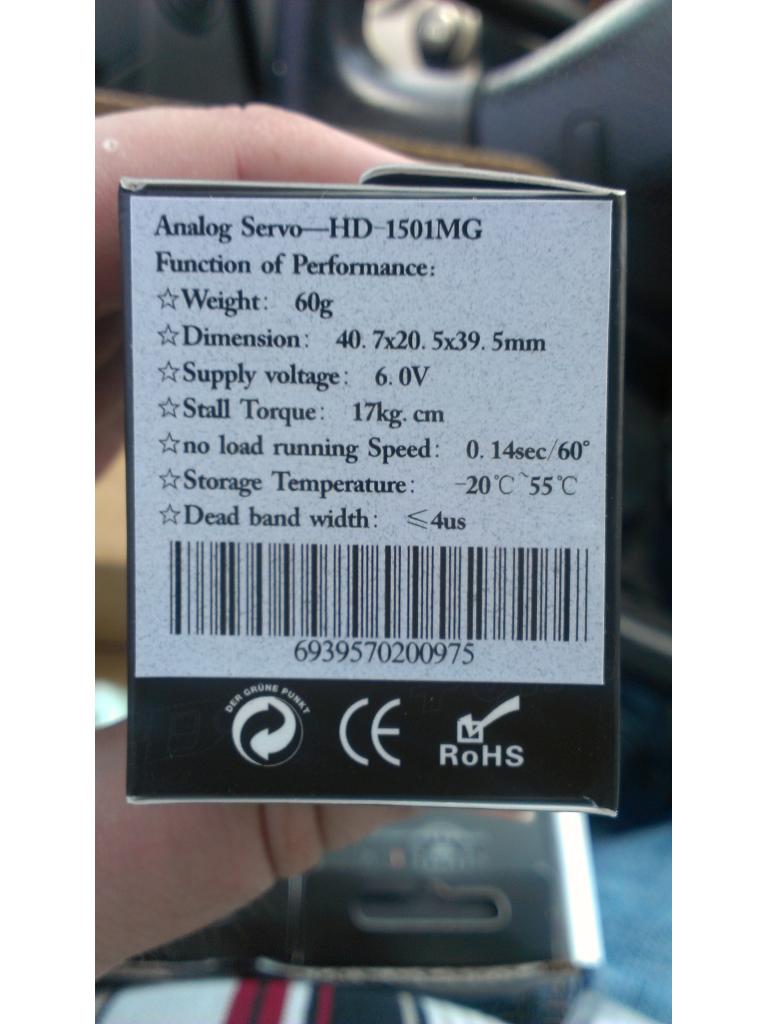
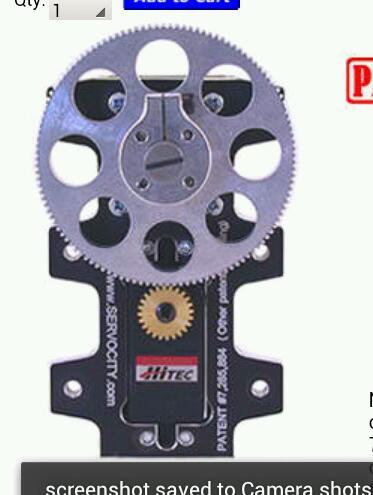
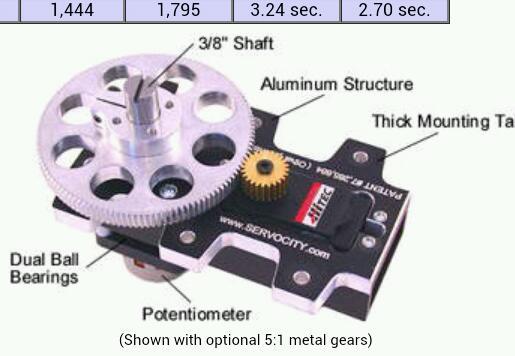
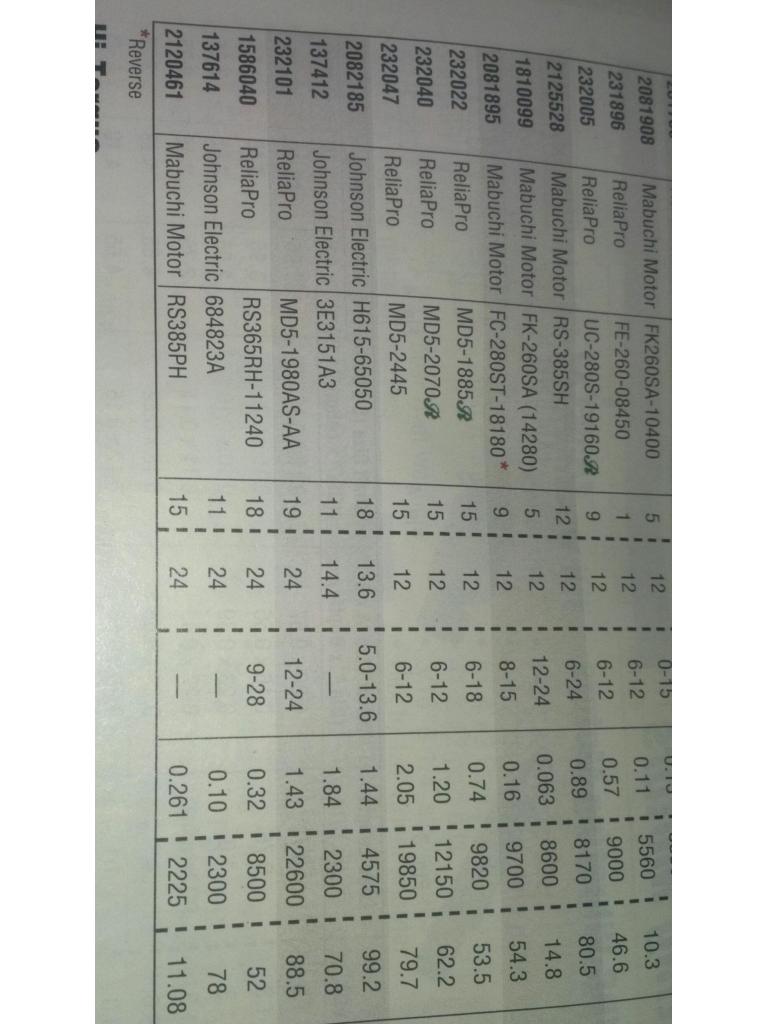
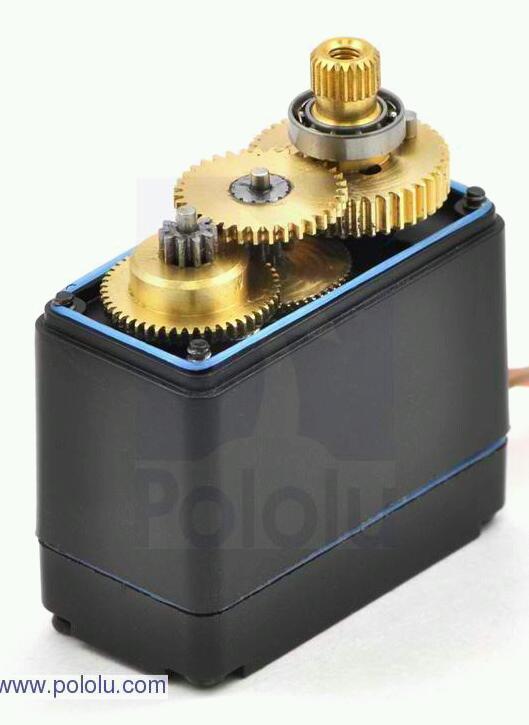
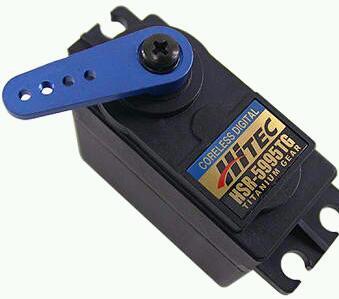
Ok I.threw out the old gearbox and coming up with something more suitable. Any ideas? Post links of ideas. Take in mind the robot weights 50 to 60 pounds at max with 5 batteries. I'm considering high torque continuous rotation servos , either two servos , one driving right one driving left or perhaps 4 continuous servos... Hmm
Hmmmm.... What was the problem?
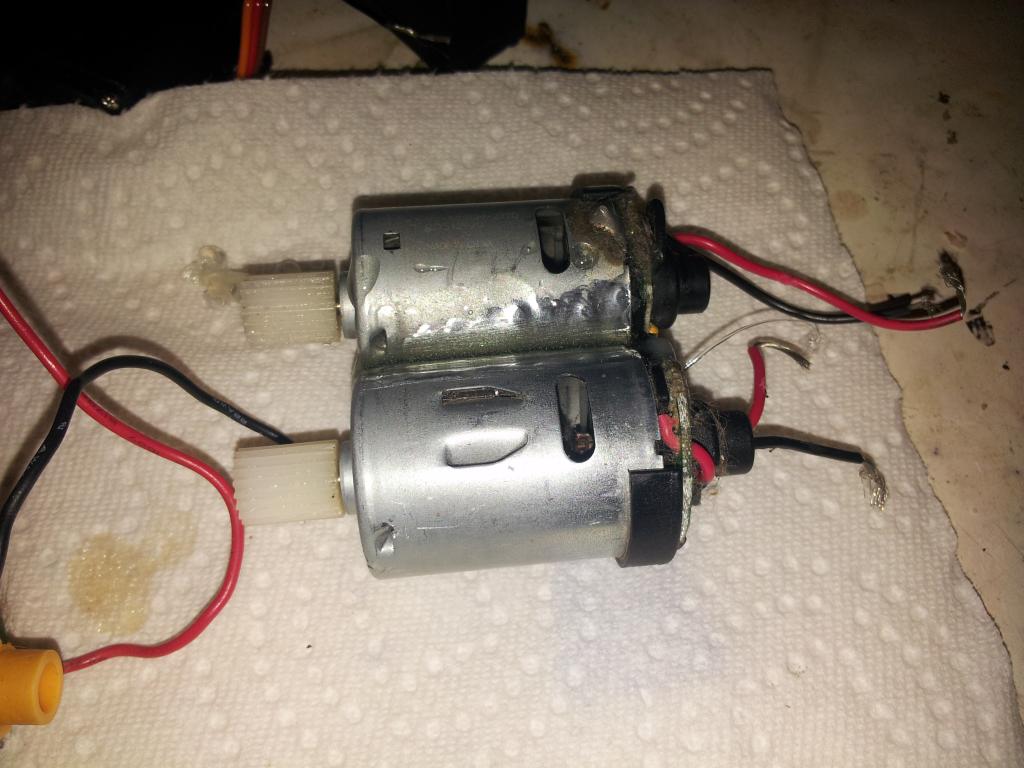
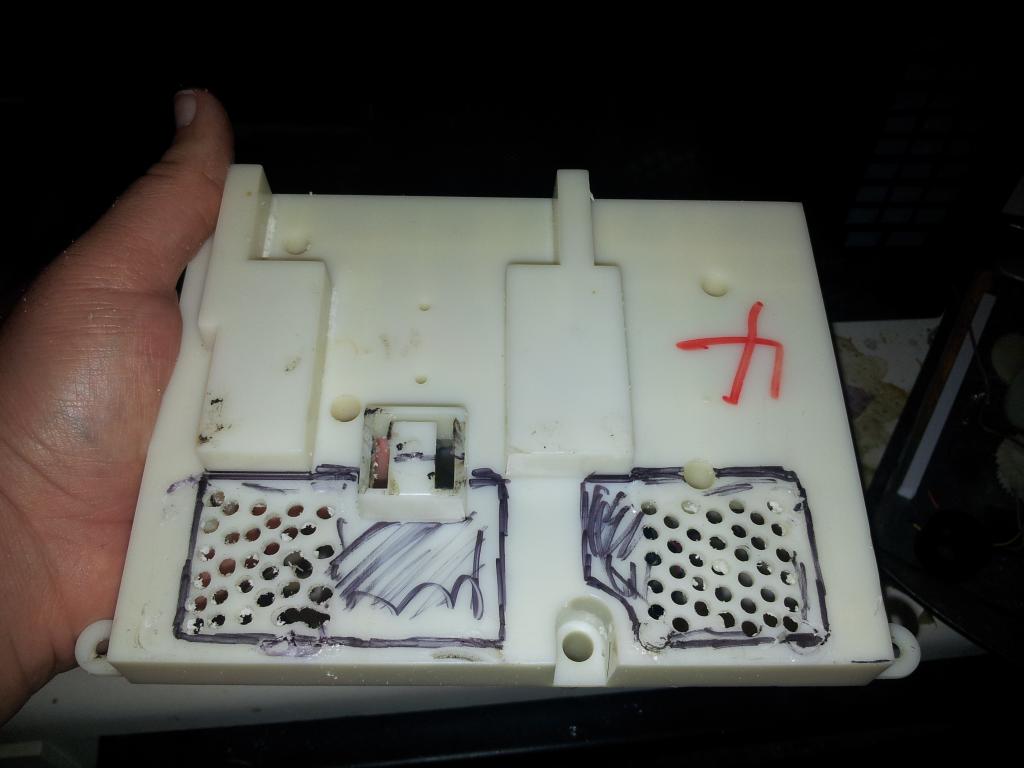
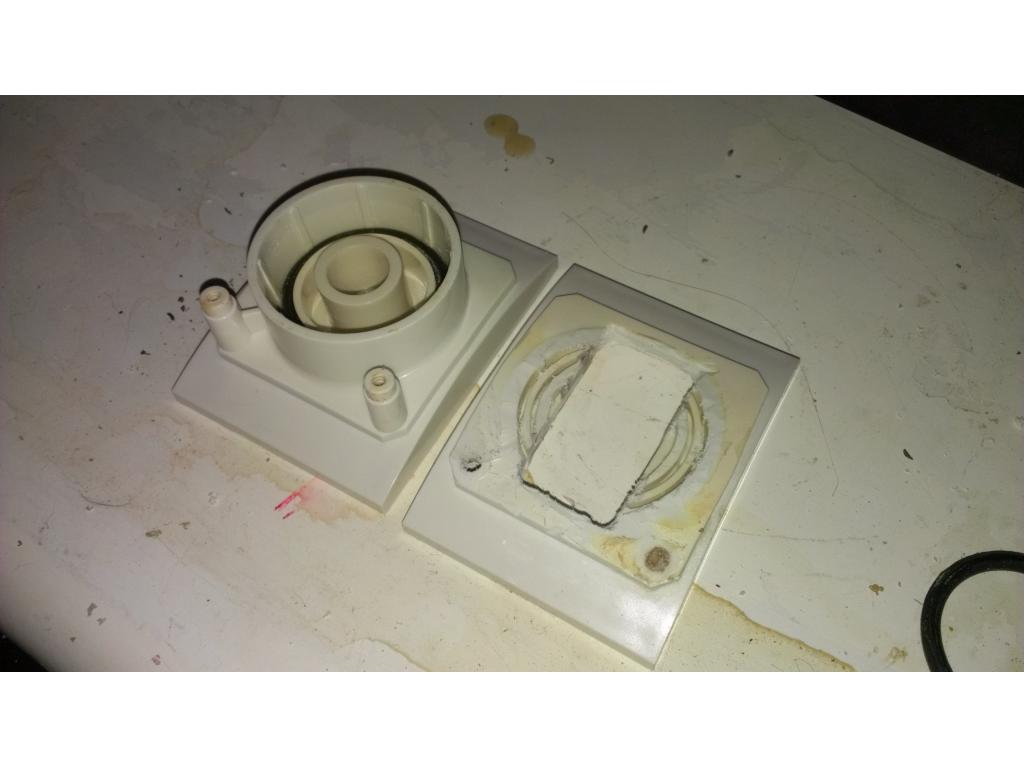
When I did the 180 turn on the bottom of the base the gearbox is too long to fit, so now I'm looking at servos or motors to use.
Have you checked into servocitys geared motor solutions?