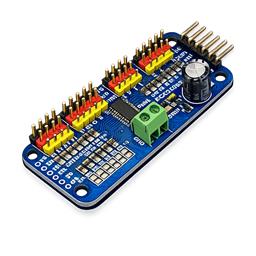

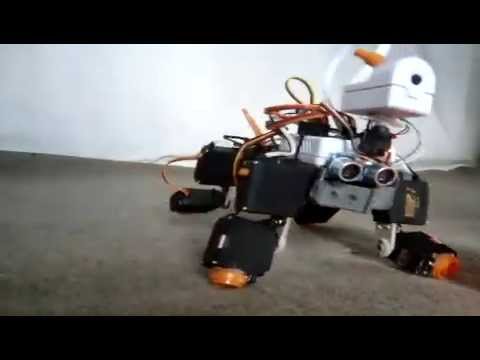
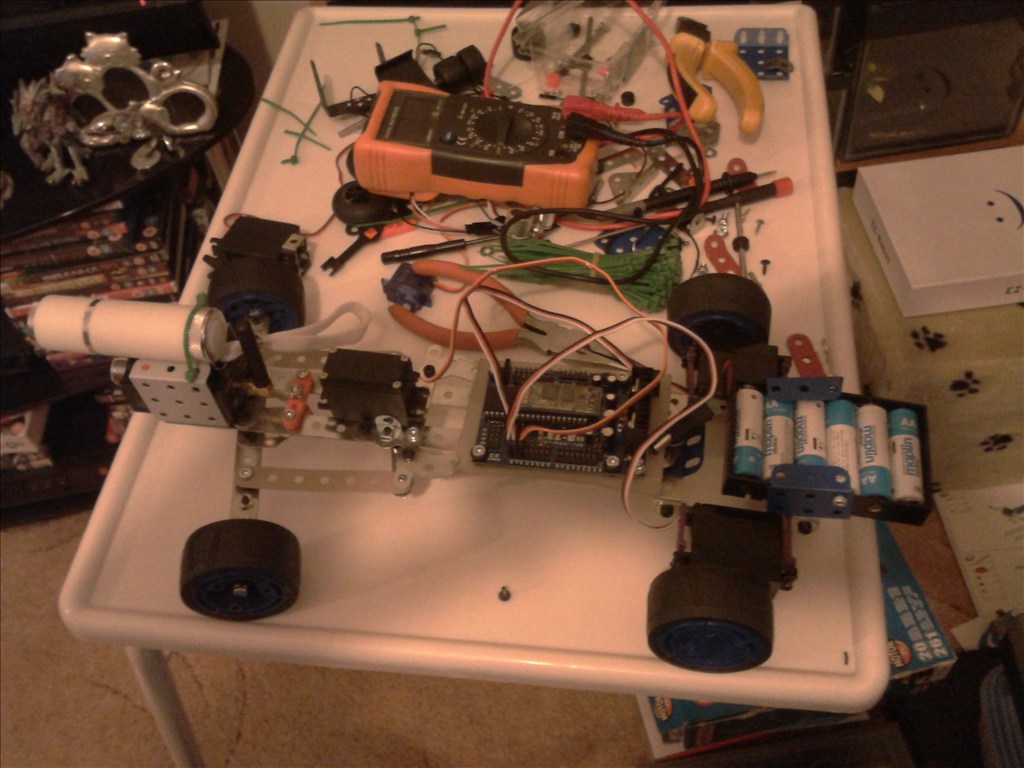
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.

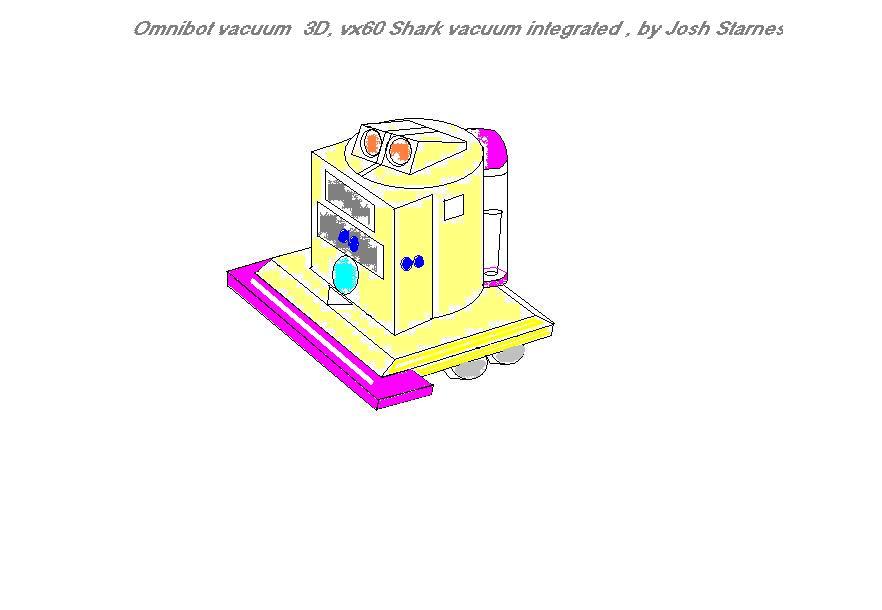
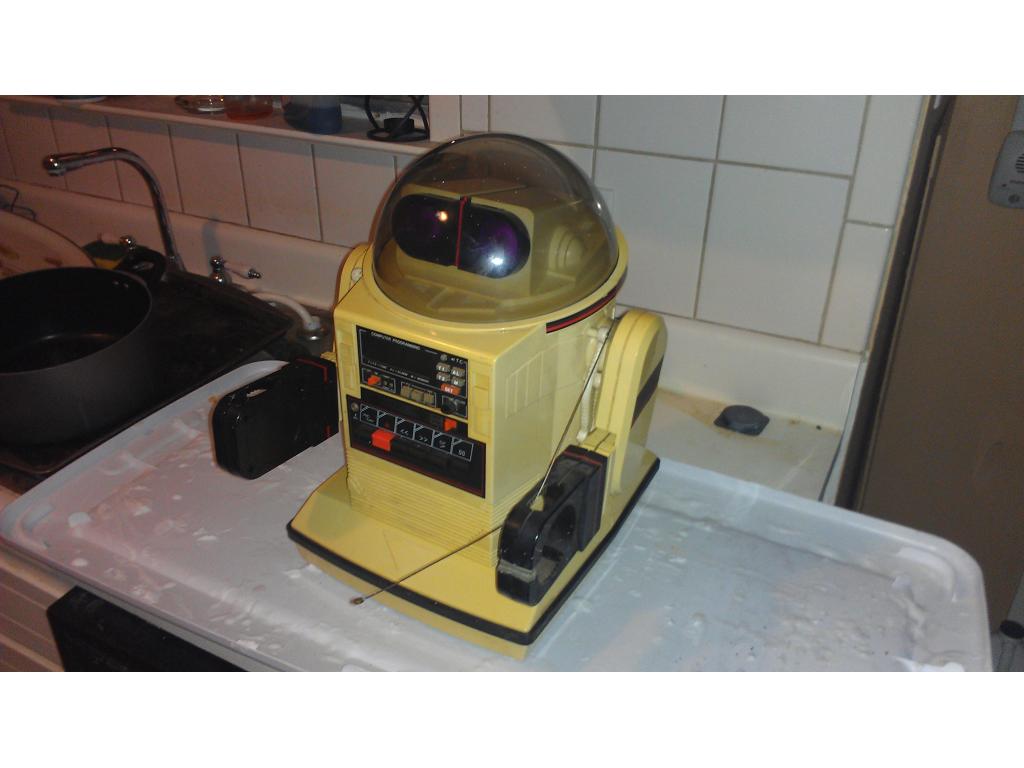
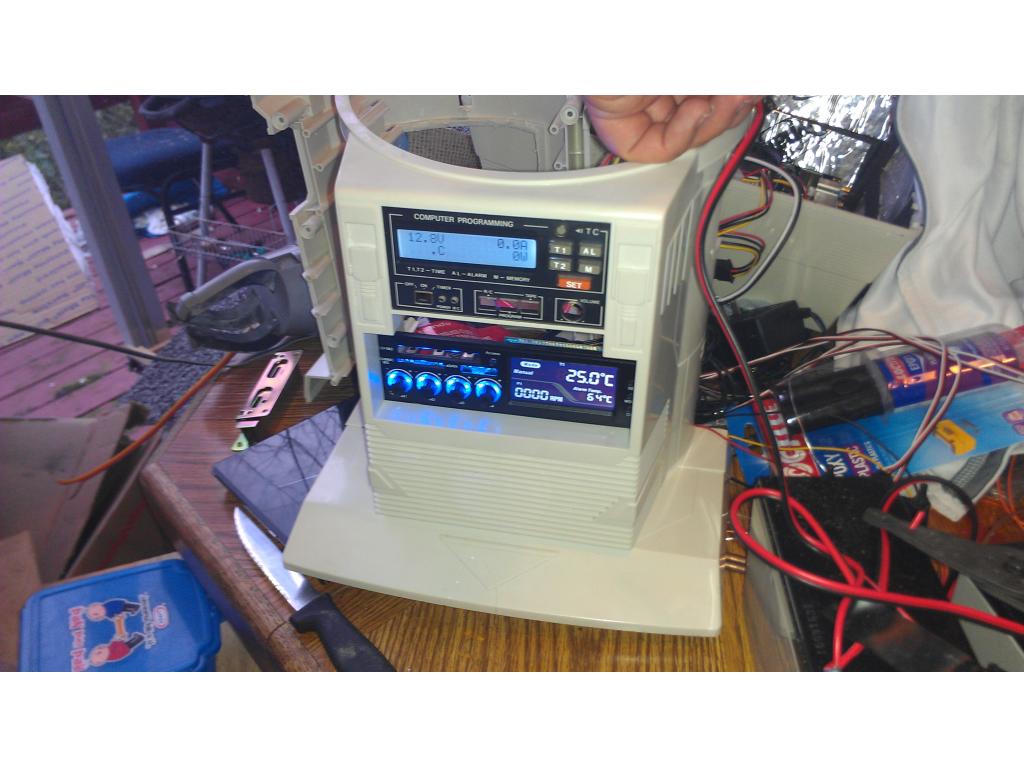

I think it's too late. I don't understand the above.
mostly for JOSH cif needs more info on how to modify the board for his robot ,can explain it better i guess JOSH would need me at his house
Possibly means that the board wont operate if it cannot sense the motors after removing them? Place a resistor where the motors were connected to fool the health check on startup?
(replaces babel fish and tries again)
I've heard of just using the roomba board all together , h bridge to power the motors and sensors to guide it home to dock. Is this a good idea @robotmaker? Just gut a roomba.
yes thats what i said,it will work perfect,also free up some ports too,it has a built in navigation software MOTORS I GAVE YOU ARE FROM A ROOMBA,they are not the drive motors but vacuum motors with more torque ,but will work great with the board one very small problem using the motors they do use a single optical encoder,so you might need to add them to your design,simple circuit,slotted disc and led and detector,can easy remove them i am working on a better quadrature optical design for roomba ,and made a double battery switching design,one i made for MEL'S roomba turtlebot i sold him
Hey Josh, I have a new board for a roomba if you want it. Never been used.
Bret
thats a good ideawill need the sensors and the omnicone on the front panel,front panel has all the sensors,i dont have any extra covers with sensors,all been modify for my ROOMBA TURTLEBOT i am selling ,look up turtlebot on the internet ,its $500 without a laptop,selling mine about $250 with 3 decks,they use the IROBOT CREATE witch is the same as ROOMBA only connections out easy access and no vacuum motors or parts mine also has a second battery design to handle laptop and KINECT sensor on ROS software
This might be a dumb question but which roomba board is it? odel number it came from , I ask because there are a handful of roombas that don't have the docking capability/ feature