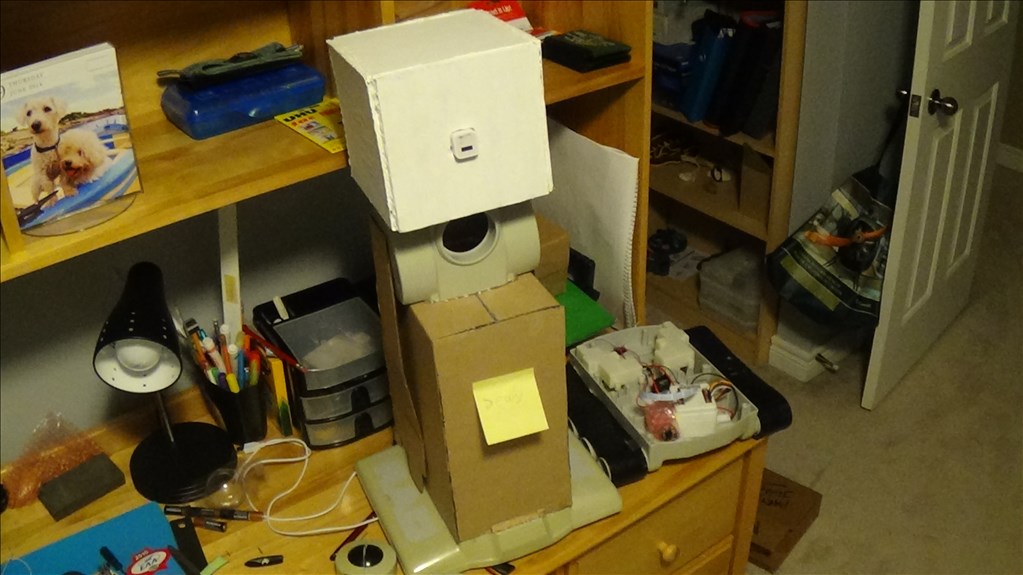
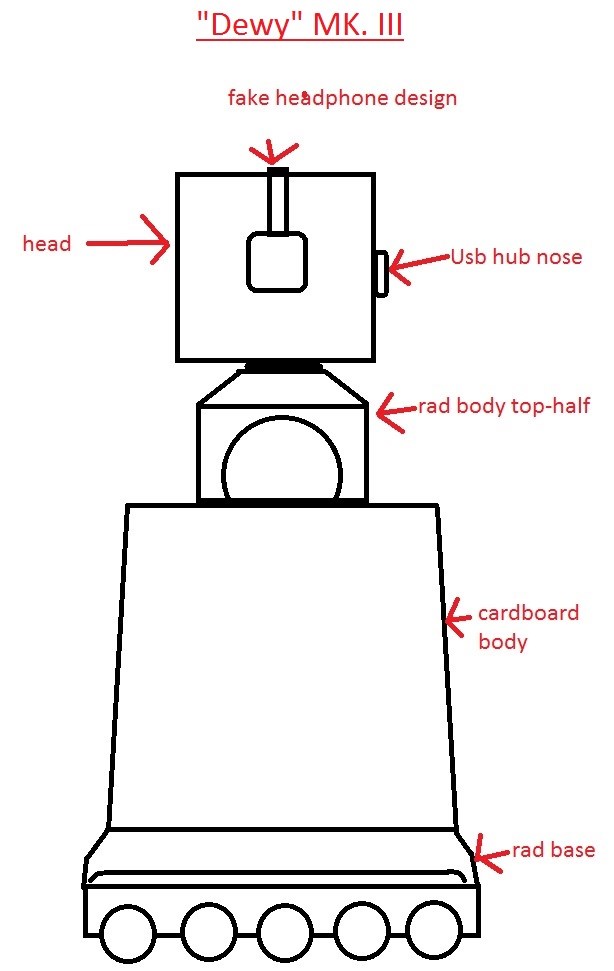
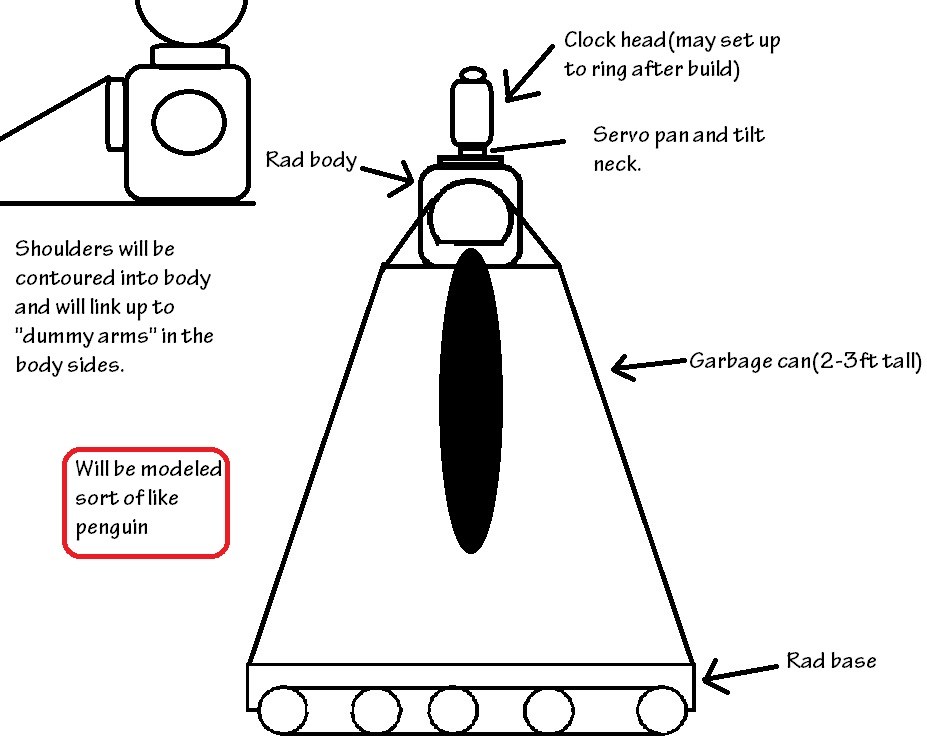
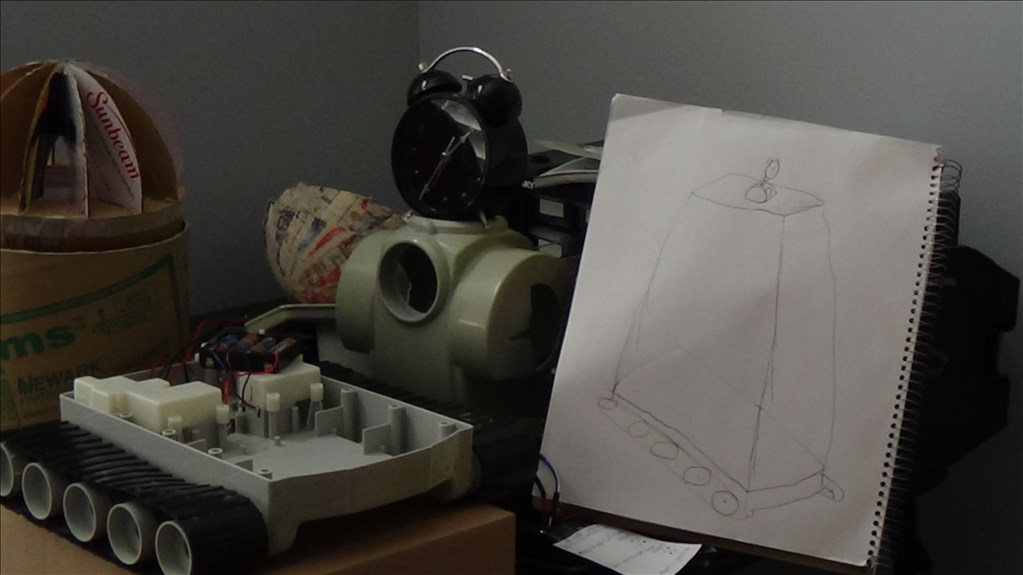
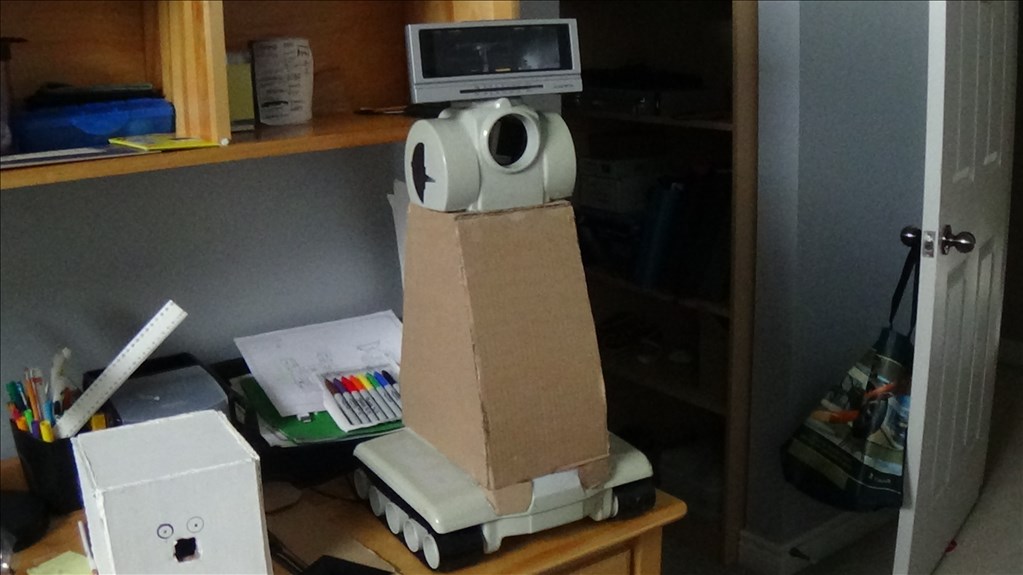
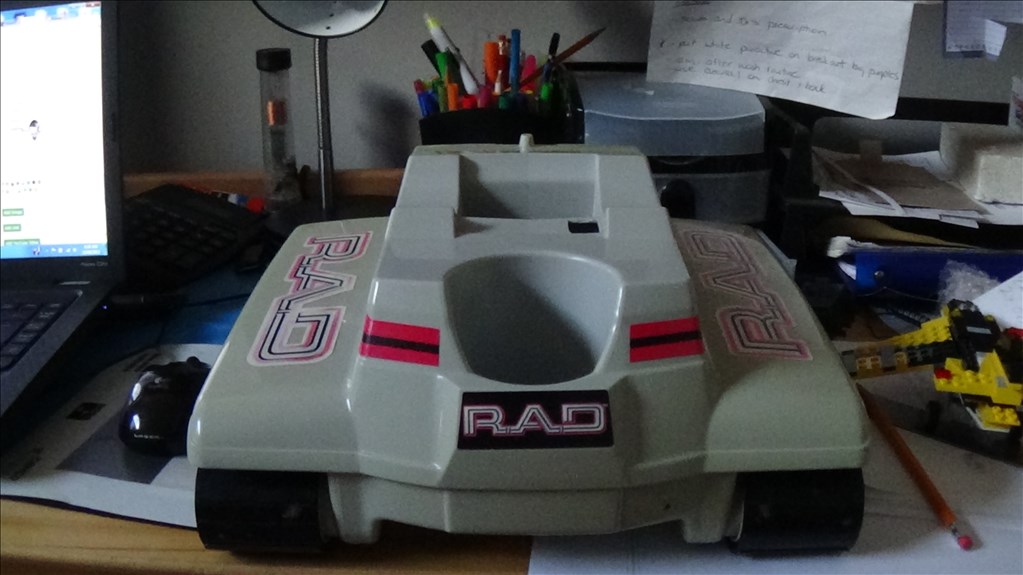
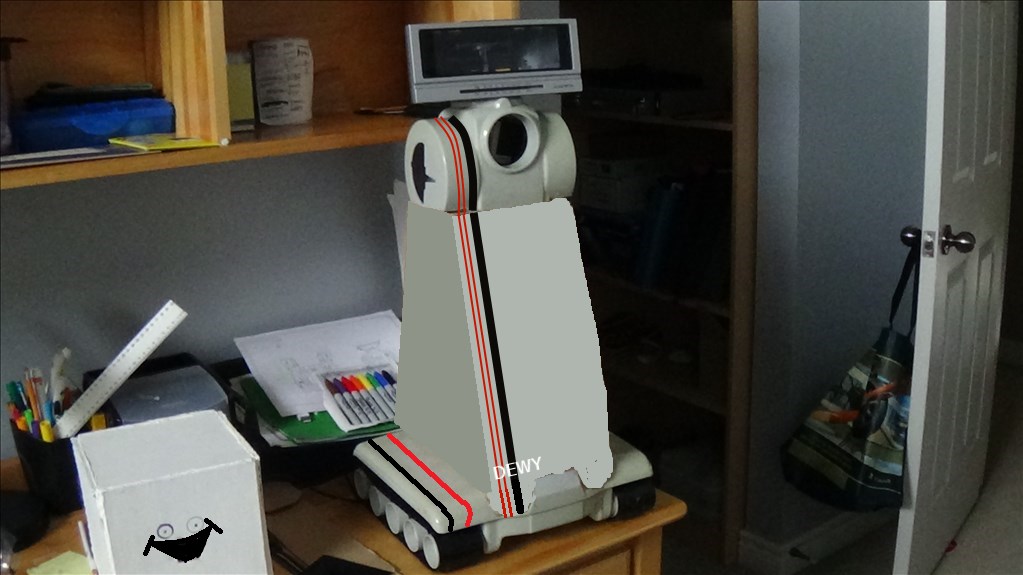
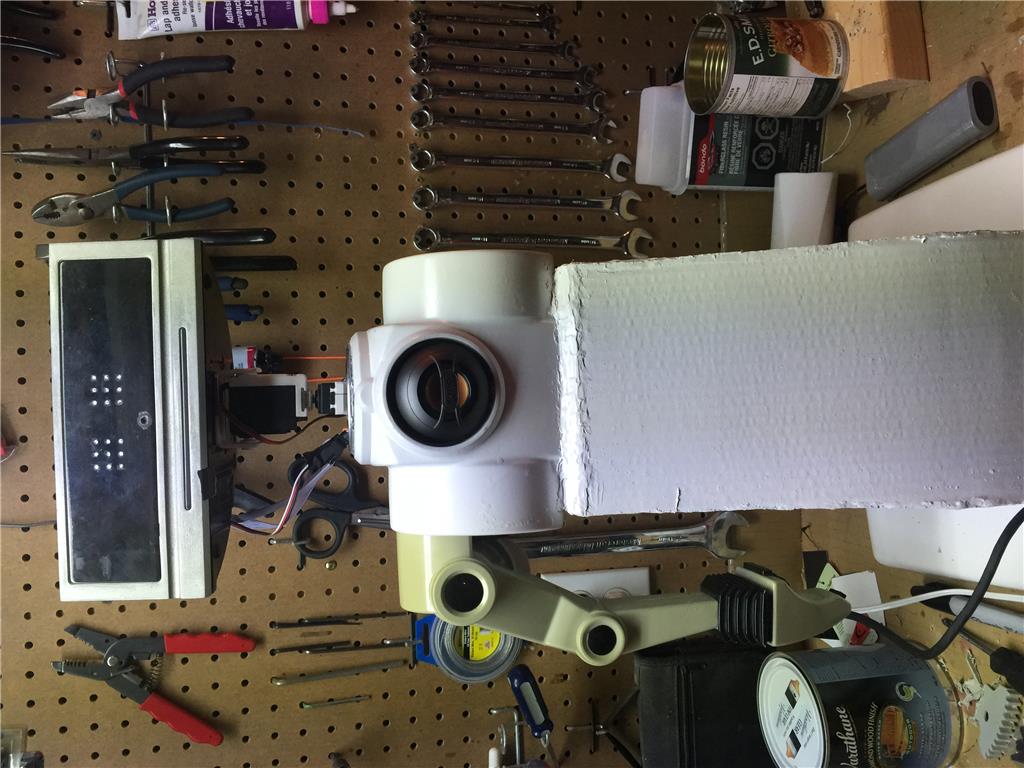
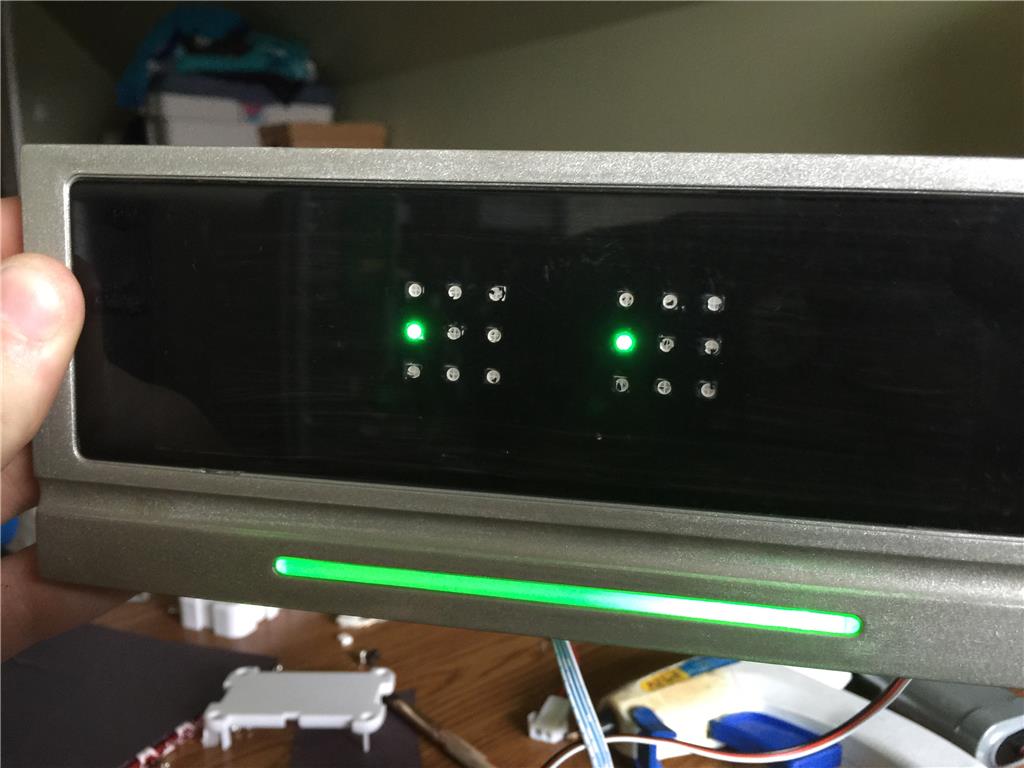
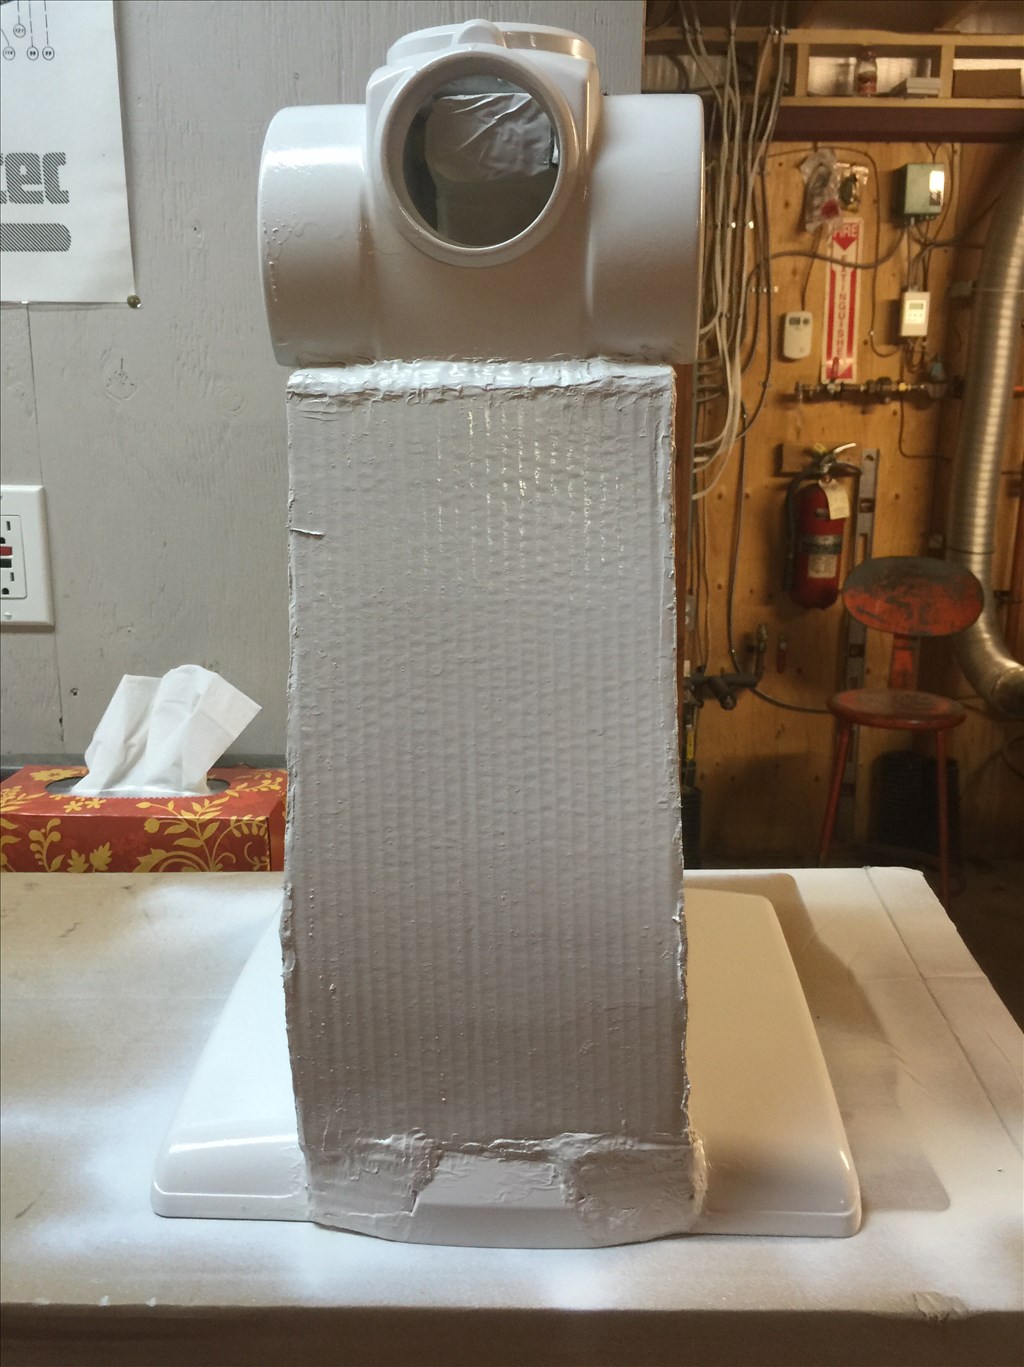
This is the thread for my current project Dewy. He is a tall robot that uses RAD parts and models a omnibot in a way.
For showcases sake:
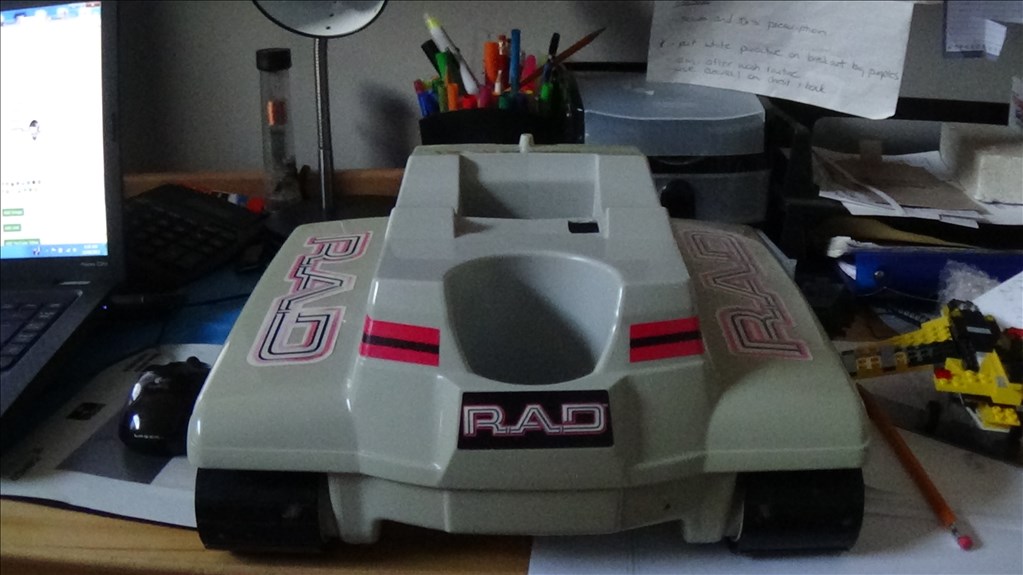
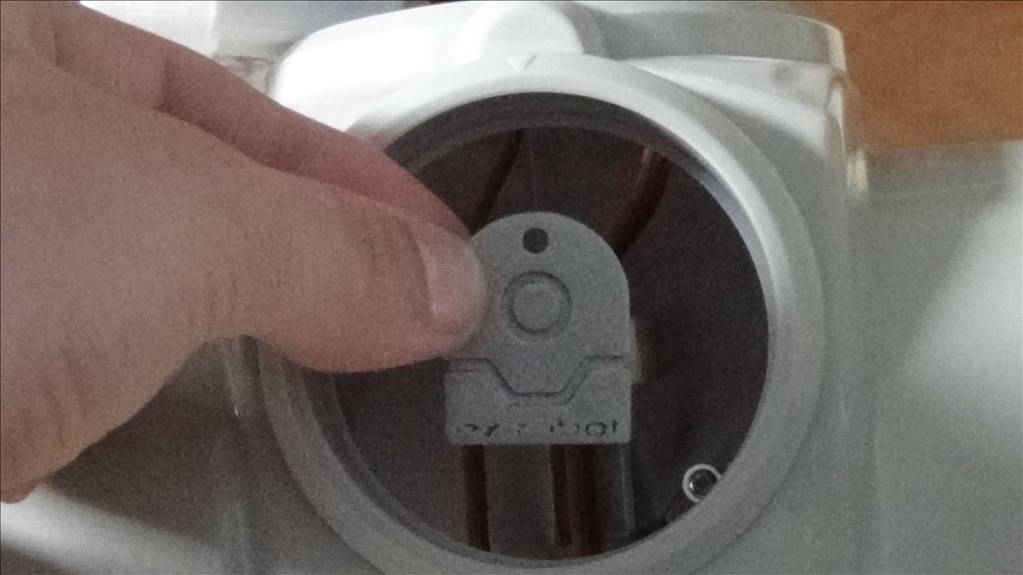
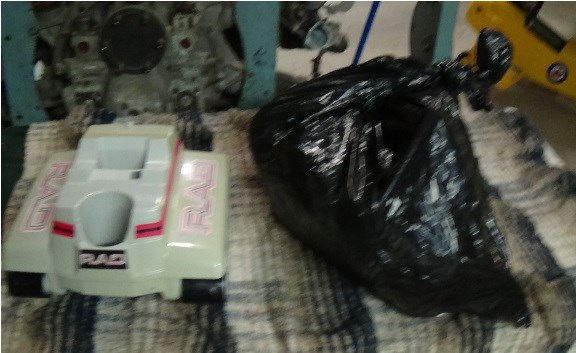
Here's the process of tearing down the RAD.
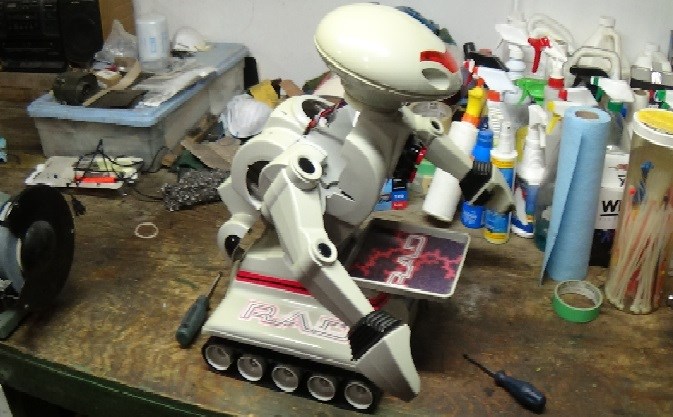
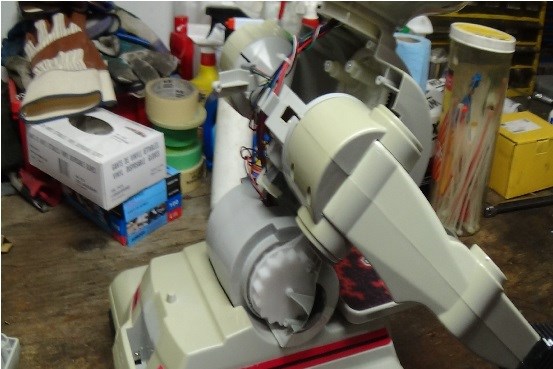
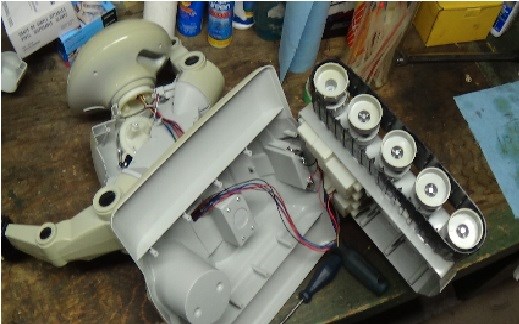
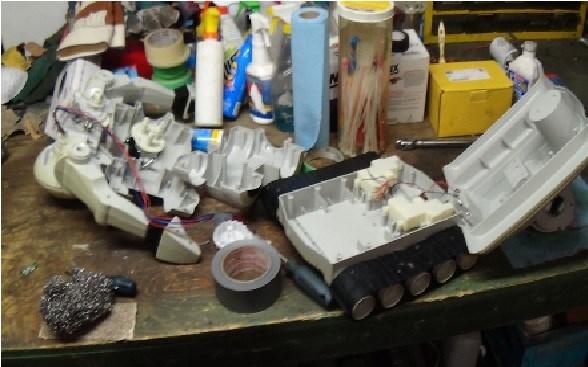
Here's where I finished off.
By CardboardHacker
— Last update



Discover more robots
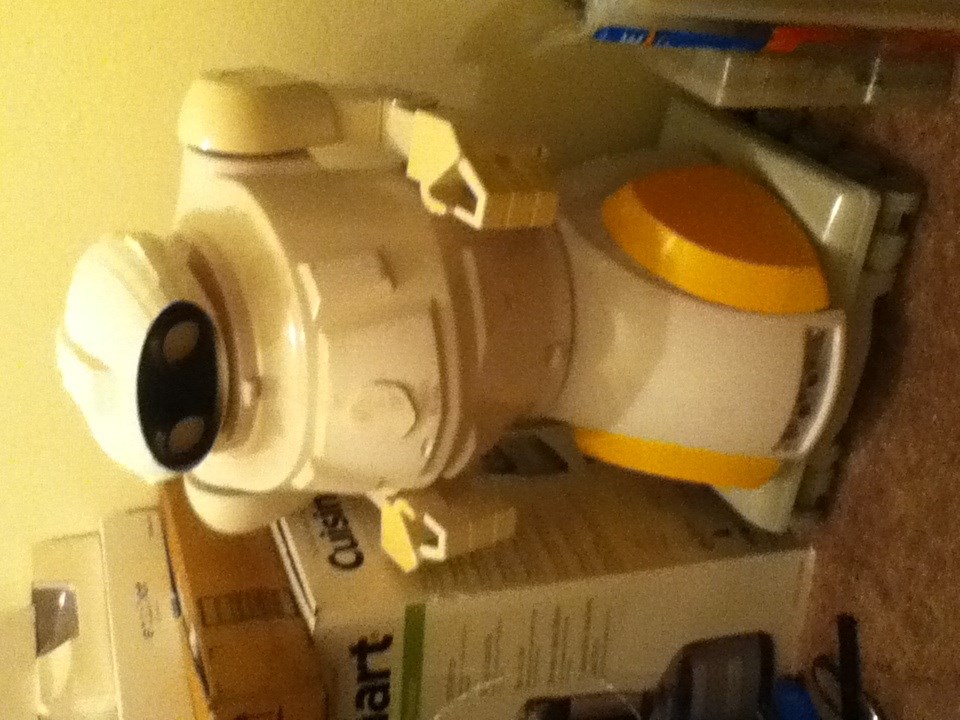
Linux's Project Omega Status
Omega robot build 75% complete using Rad Bot 1.0 tracks and plexiglass; pending neck/head, wiring, motorized tracks, RGB...
DJ's Ips (Indoor Positioning System)
Positioning system for ez-robots after years of work and many trials, now heading to manufacturing for scheduled summer...
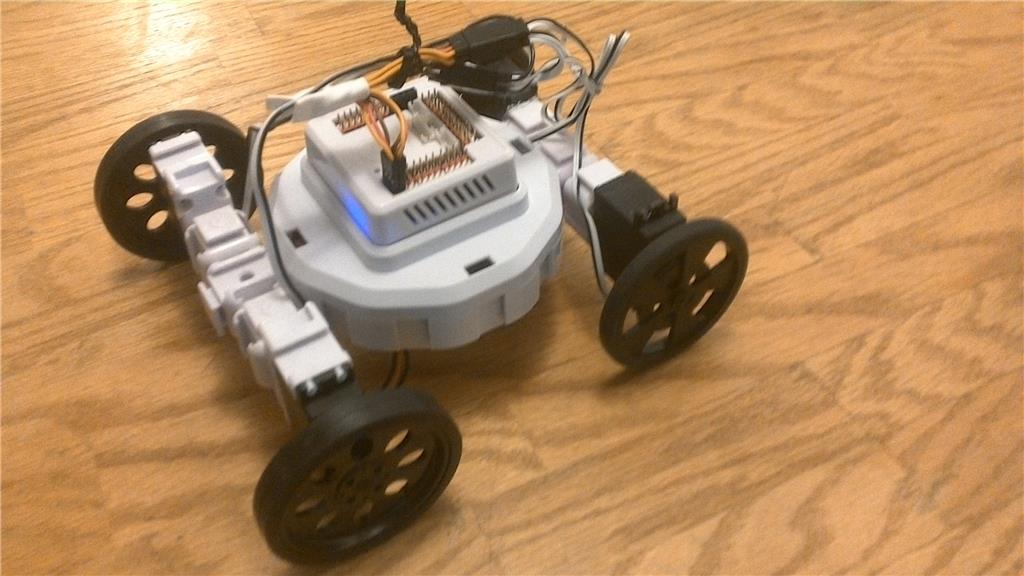
Robohappy's Adventurebot4wd
4-wheel drive robot upgrade using four CR servos with Y-splitter cables to preserve directional control; camera, sensors...

I have revised the design based on designs i made in the "penguin-like robot" thread. I figured I would post once more in that thread. It was a lost cause.
Anyways here's the current design:
hi here a link for all kinds off motor mounting.
motor mounting
Here's what I got done today. (No...,Seriously)
Looks like it's going to turn out great
great start
Nice
It's good to see Dewy coming together.
Ok so demonstrated the bottom part of dewy at school today and the younger children loved him! He is pretty loud though! working on the neck tonight and hope to have him looking around soon.