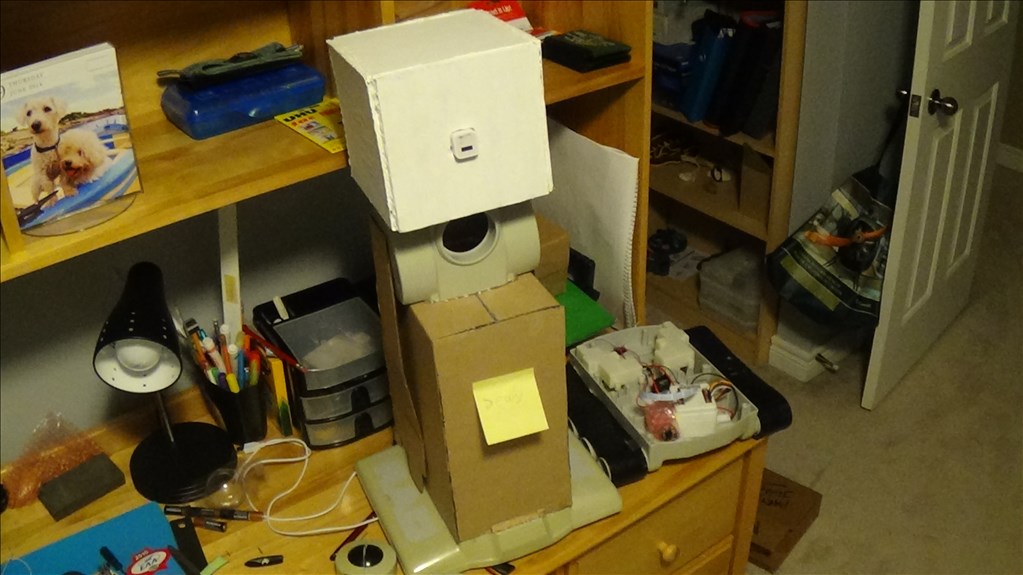
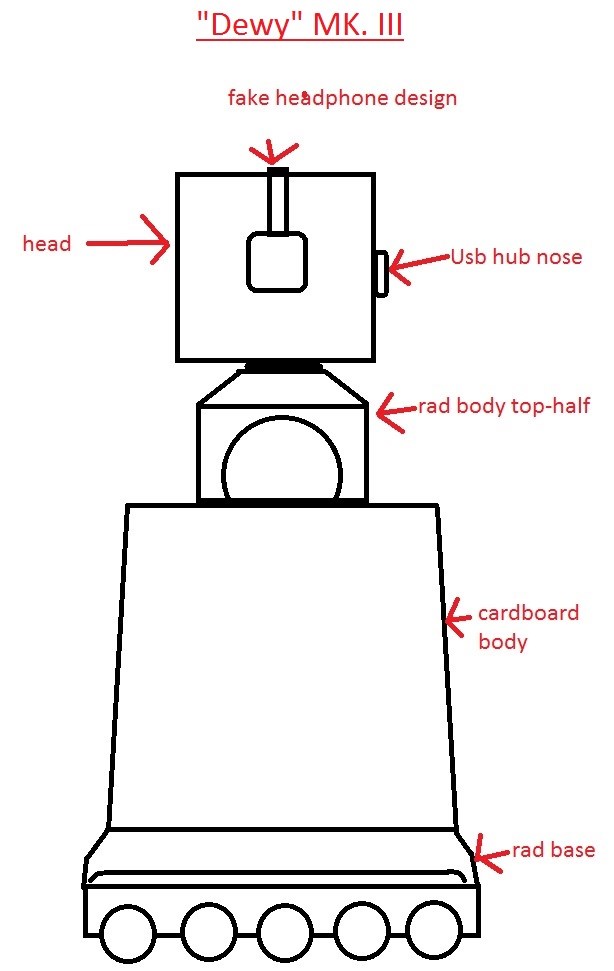
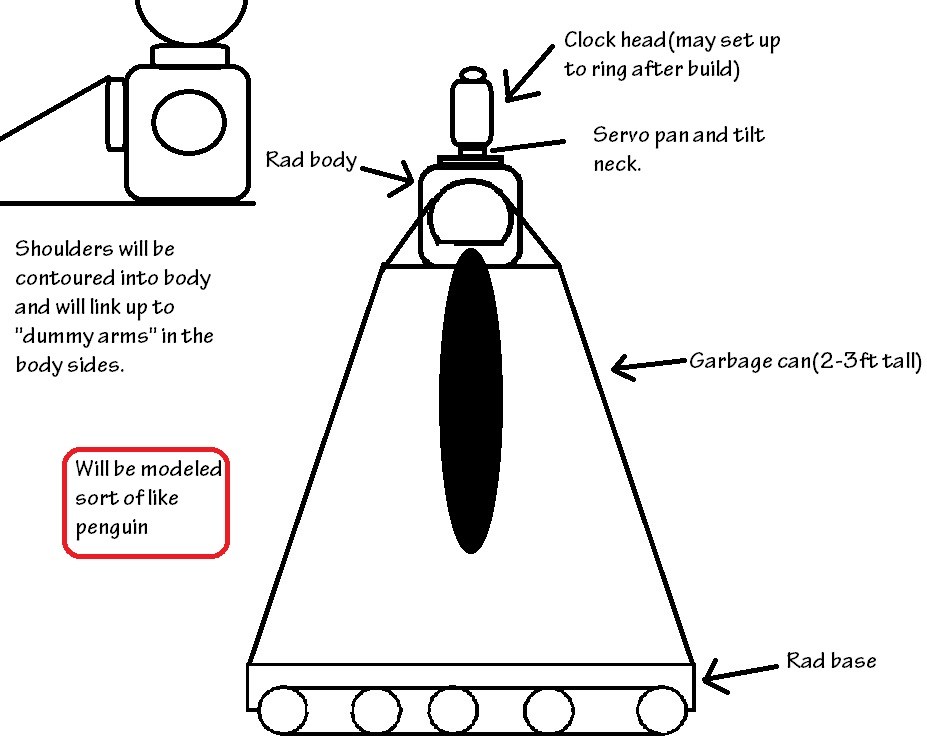
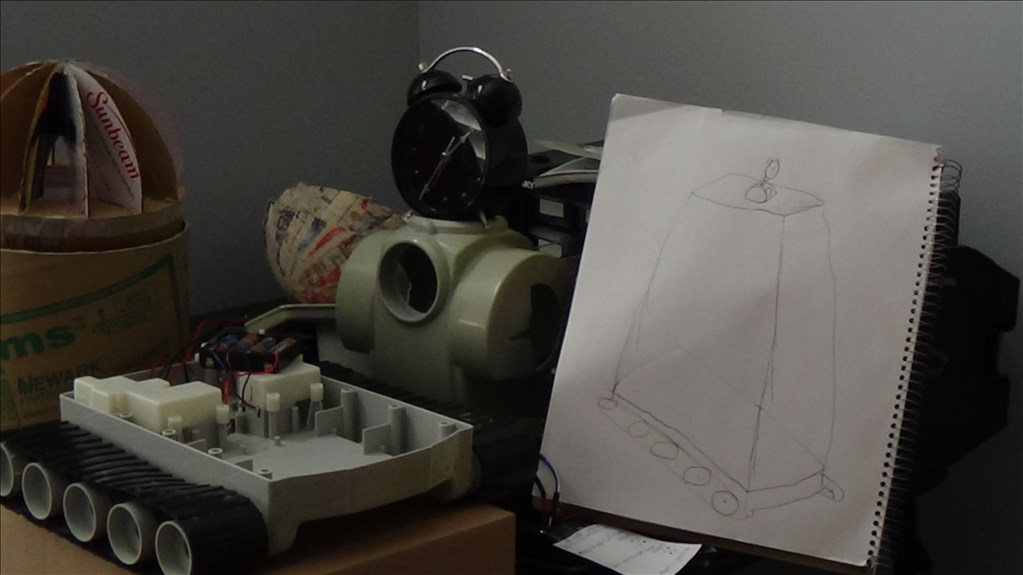
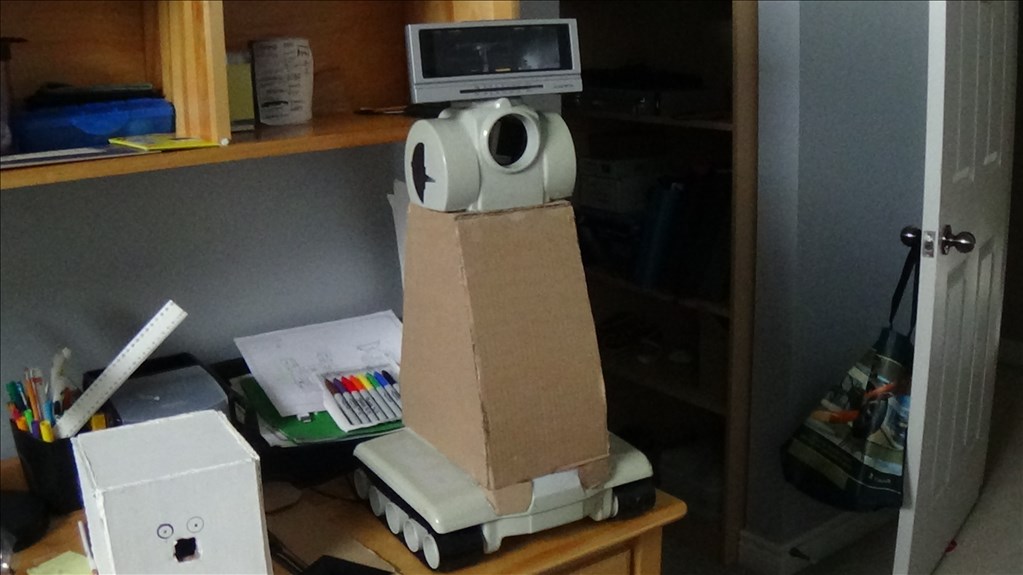
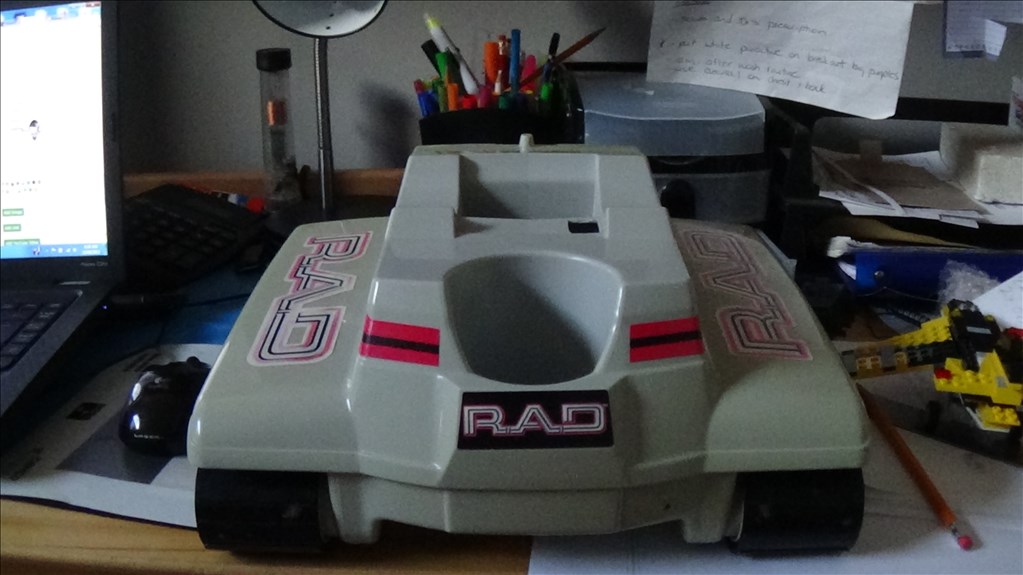
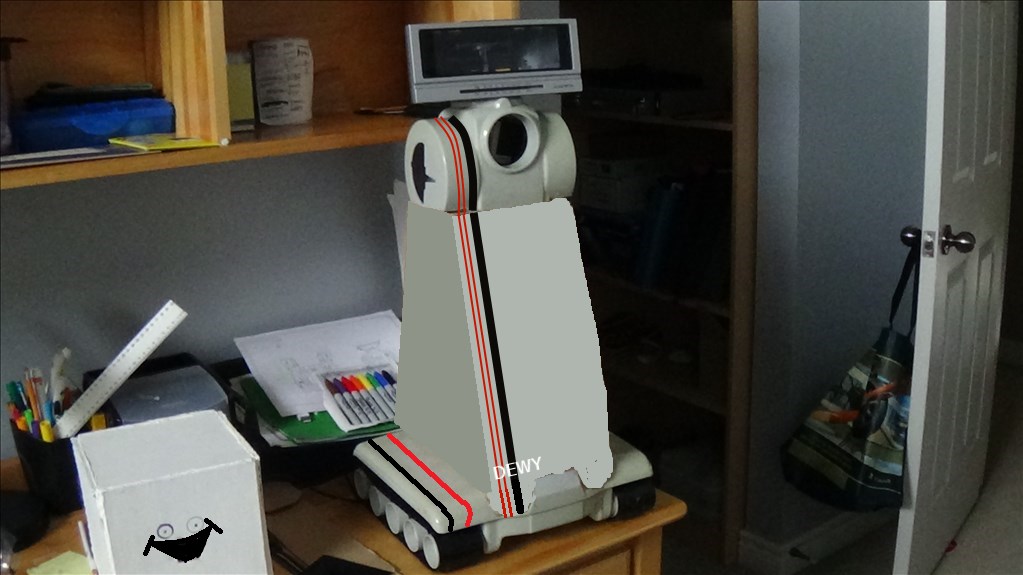
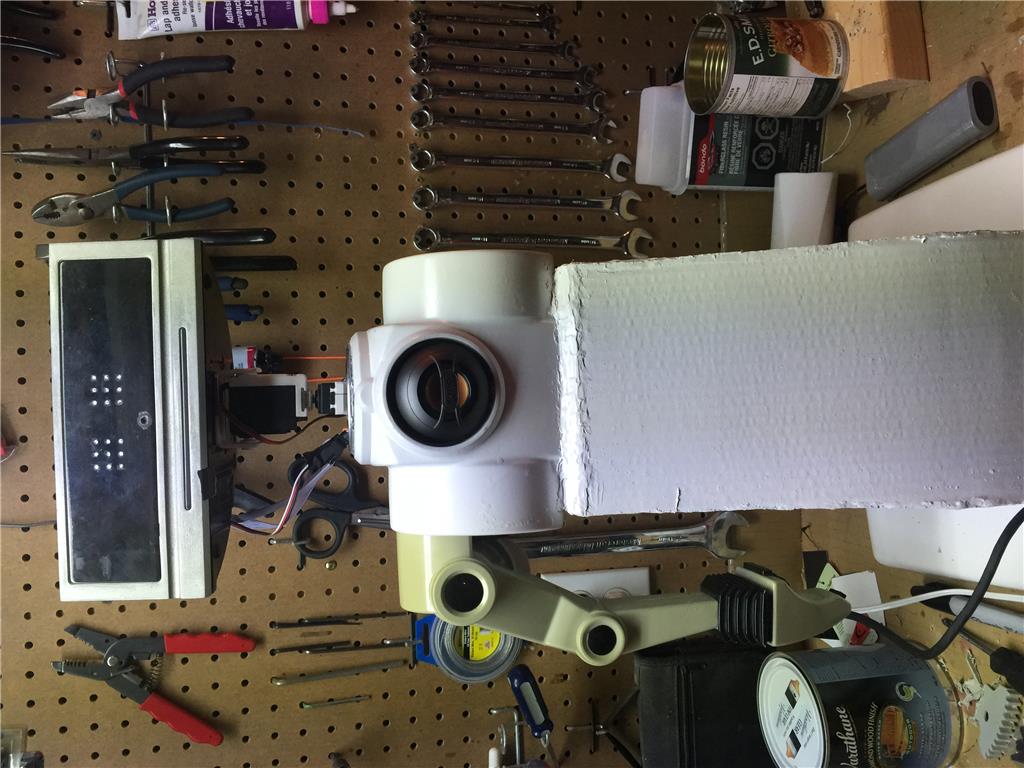
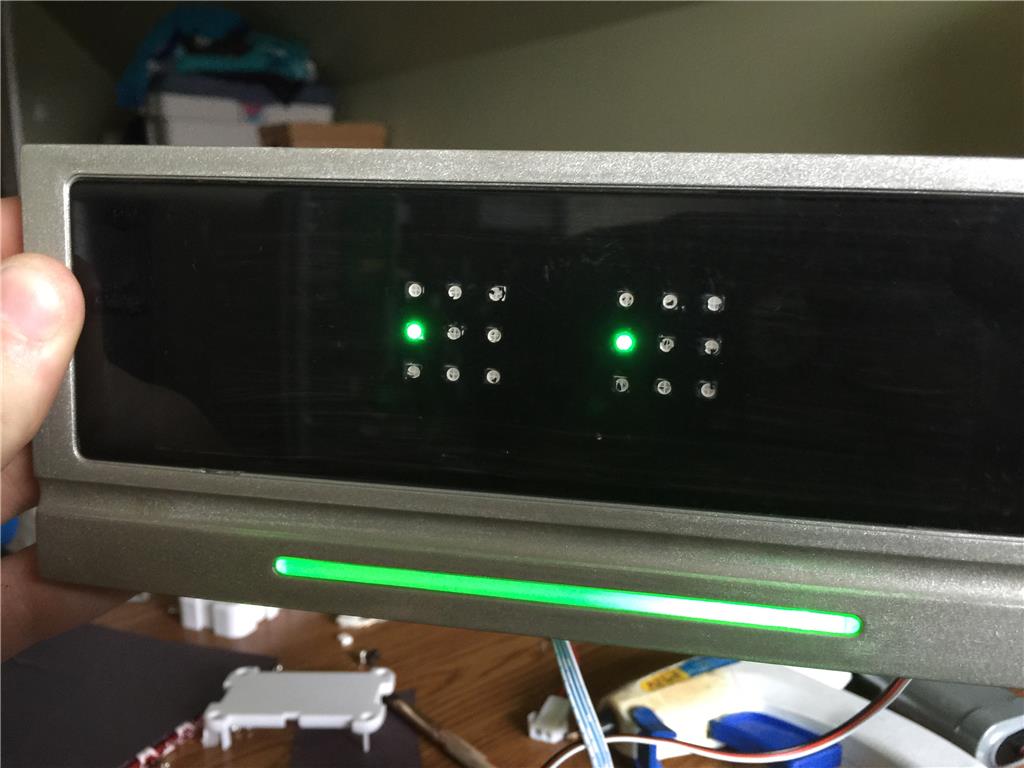
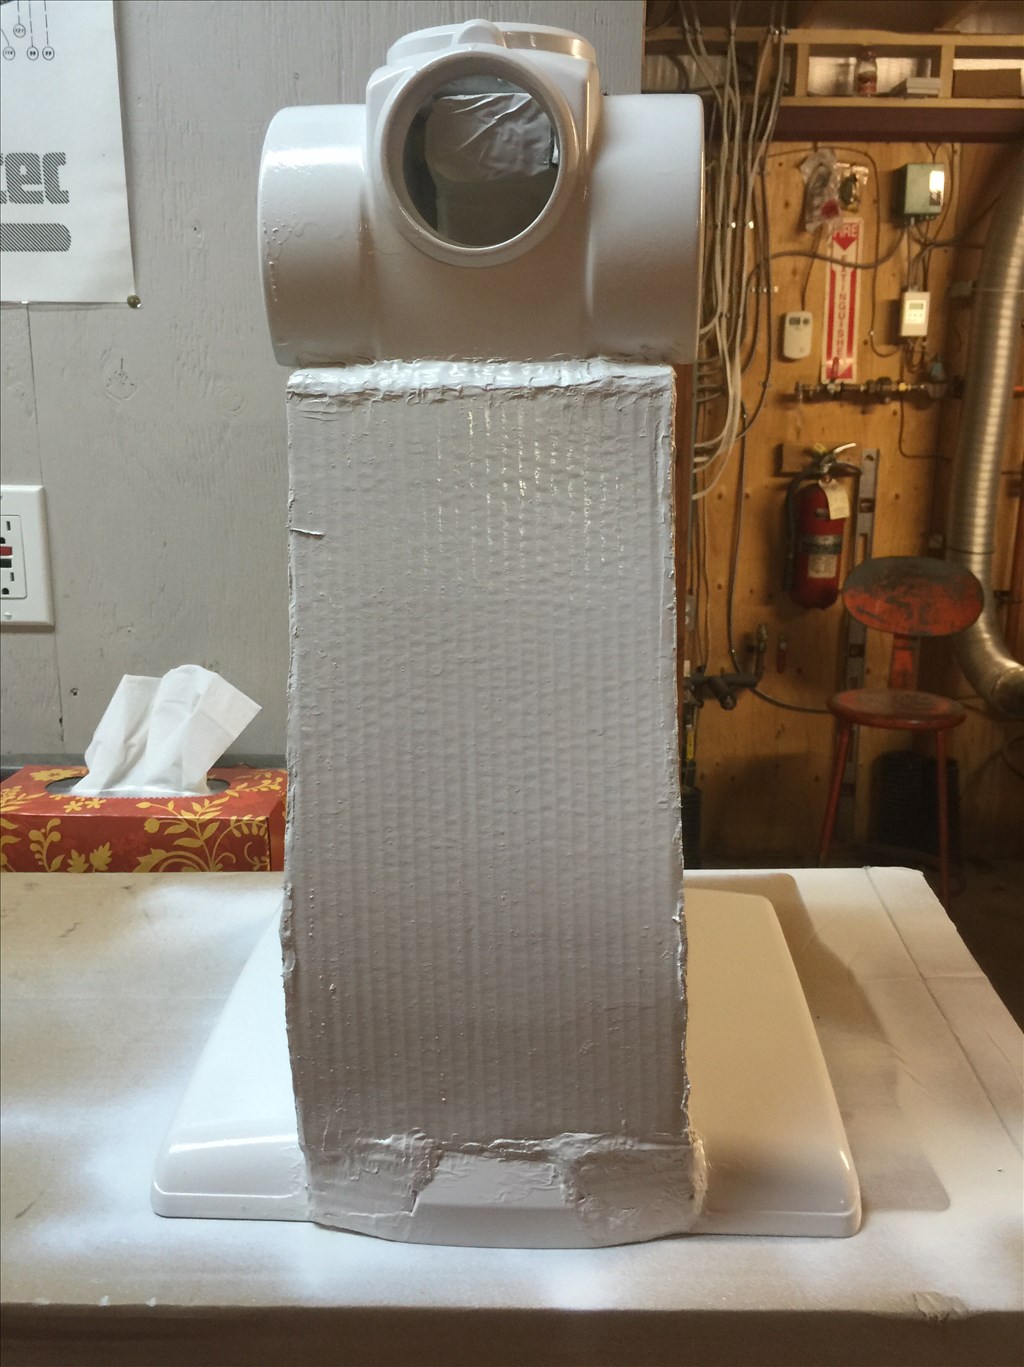
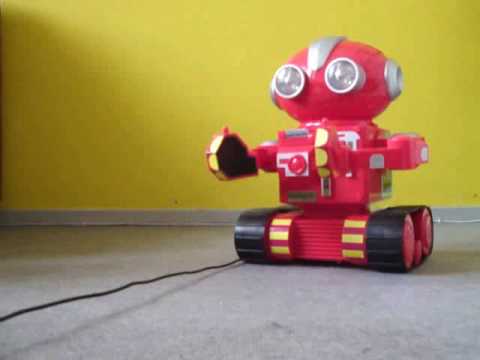
This is the thread for my current project Dewy. He is a tall robot that uses RAD parts and models a omnibot in a way.
For showcases sake:
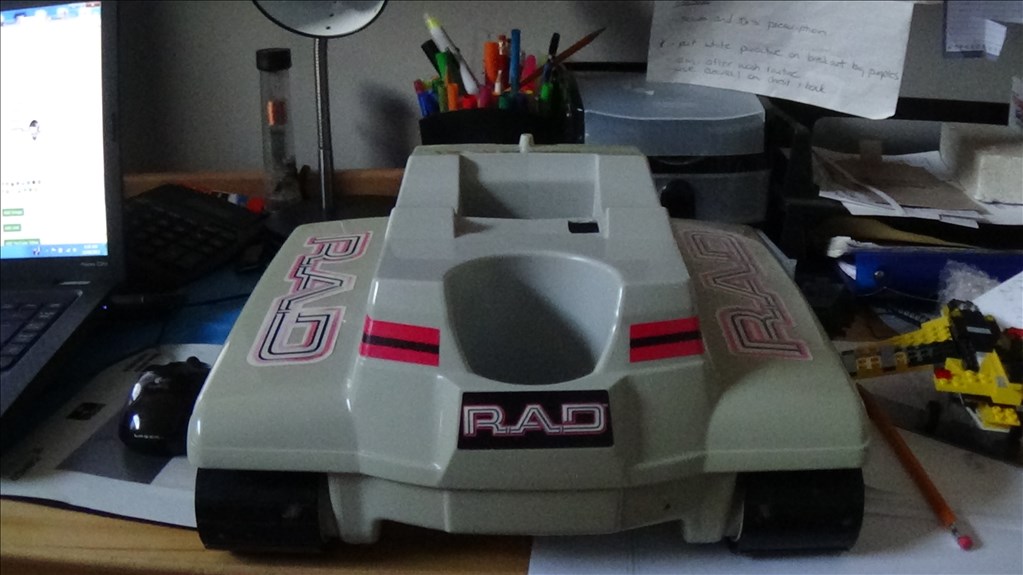
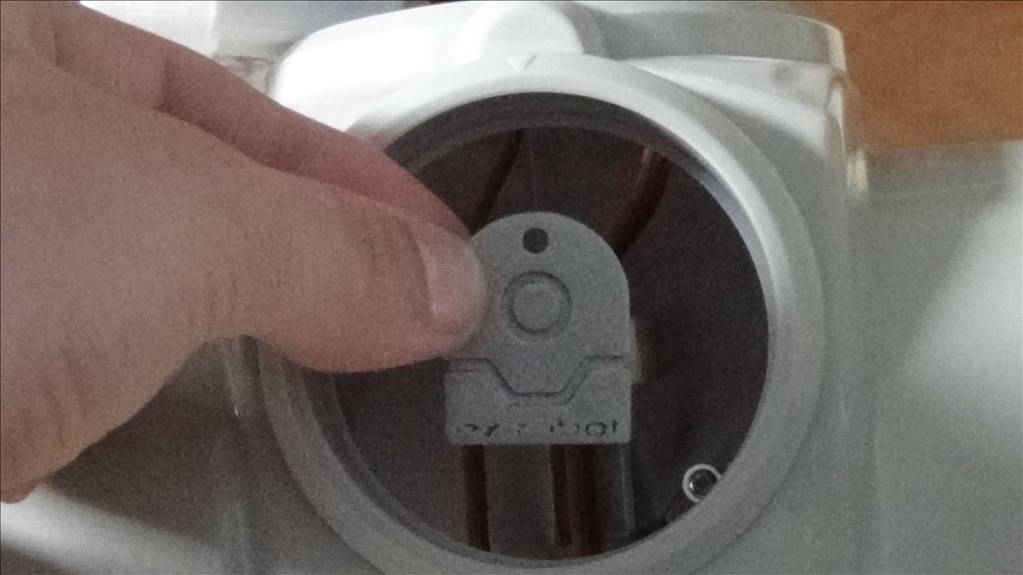
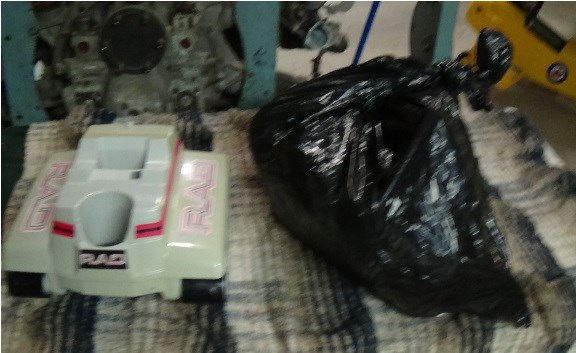
Here's the process of tearing down the RAD.
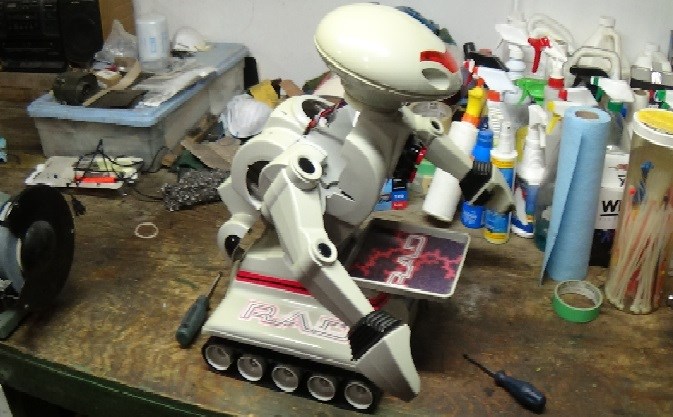
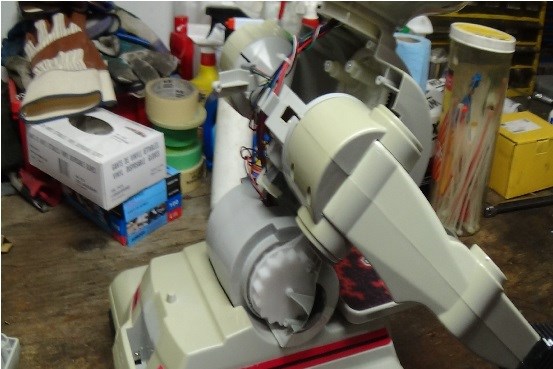
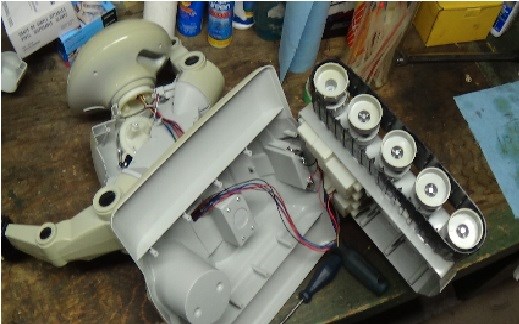
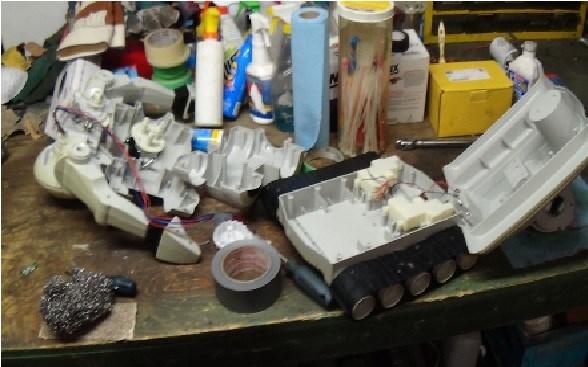
Here's where I finished off.
By CardboardHacker
— Last update



Discover more robots
Nallycat's This Robot I Am Calling Nallycat
Synthiam ARC-compatible OpenCat quadruped build using MPU-6050 for stability, Thingiverse STL/Nibble parts, mini servos...
Adfe74's Meet Suki 6Dof Leg Dynamixel Ax-18A
SUKI 6-DOF biped uses inverse kinematics, IMU for future balance, blob-based ball tracking, gait sequences with dampers...
Cobra71's Beginner Starts With Dickeys Rolling Olli
Build a Rolling Olli robot with Synthiam ARC and EZ-B for Xbox360 pad control, autonomous driving, pan/tilt camera,...

I have revised the design based on designs i made in the "penguin-like robot" thread. I figured I would post once more in that thread. It was a lost cause.
Anyways here's the current design:
hi here a link for all kinds off motor mounting.
motor mounting
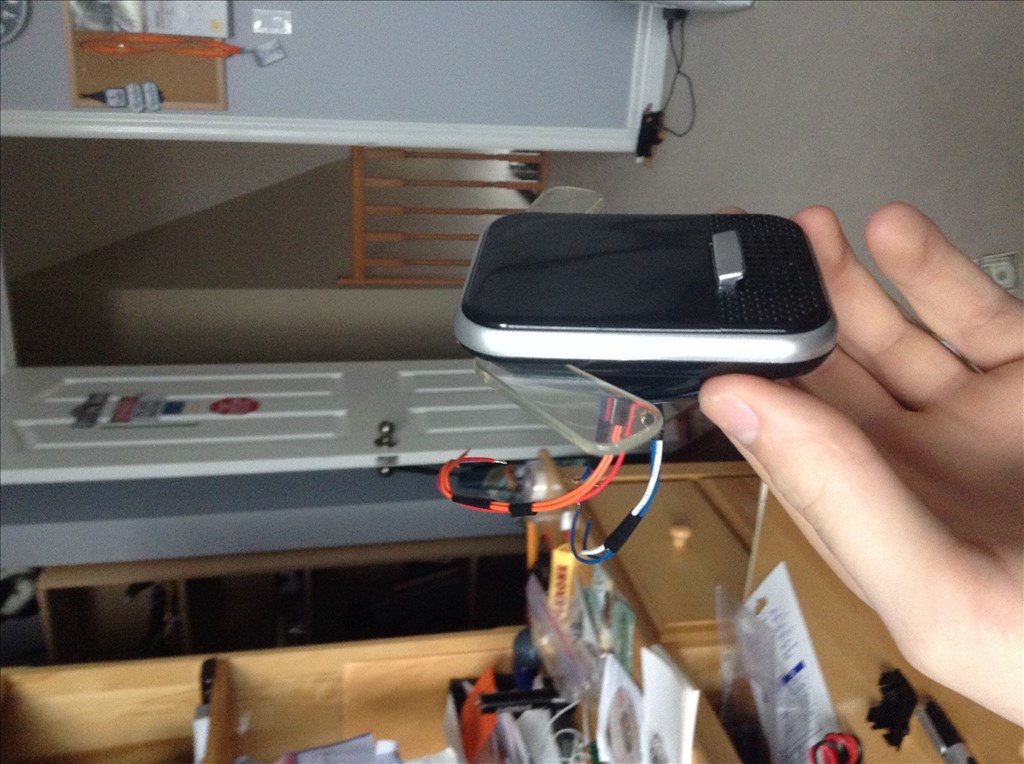
Here's what I got done today. (No...,Seriously)
Looks like it's going to turn out great
great start
Nice
It's good to see Dewy coming together.
Ok so demonstrated the bottom part of dewy at school today and the younger children loved him! He is pretty loud though! working on the neck tonight and hope to have him looking around soon.