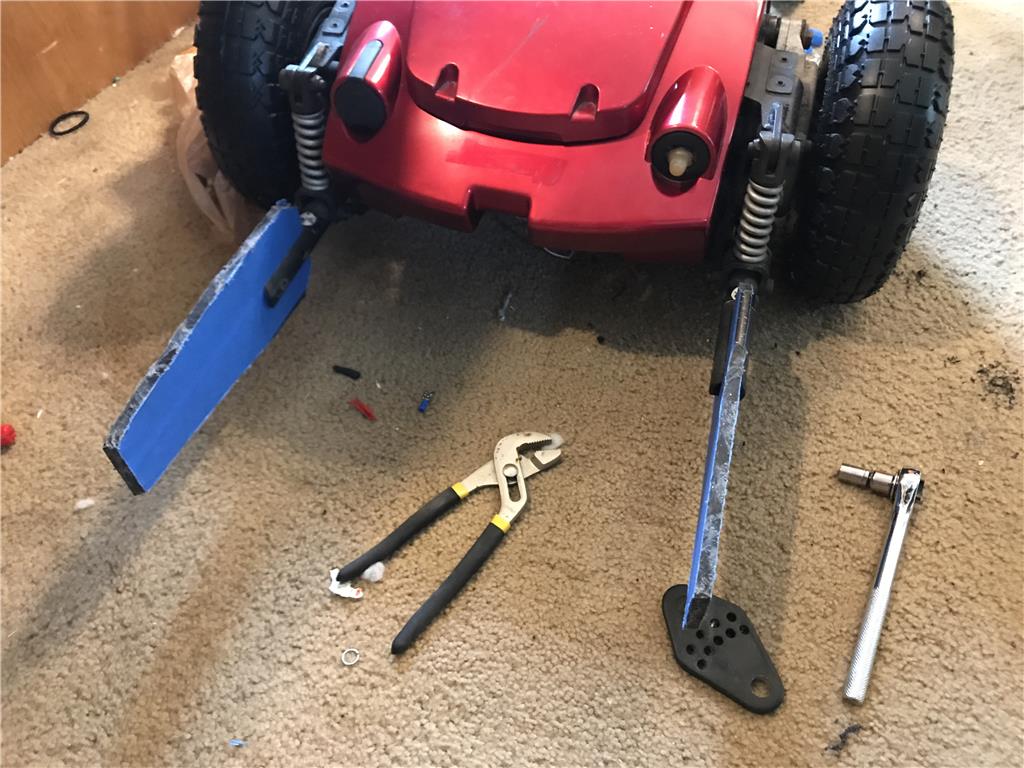
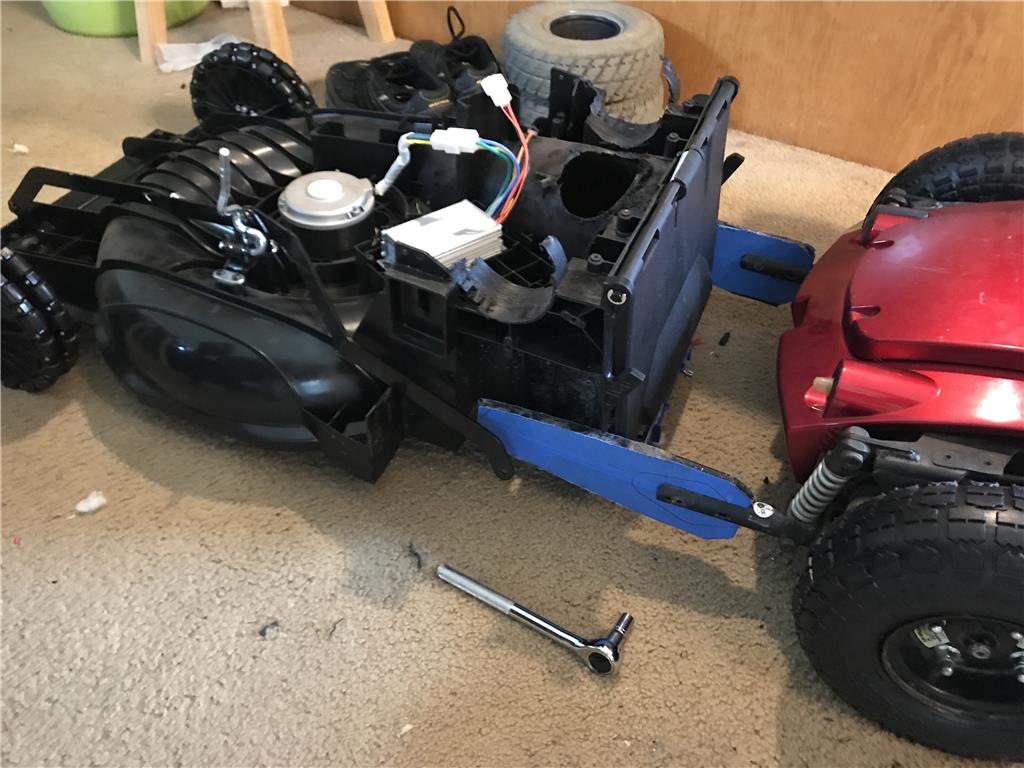
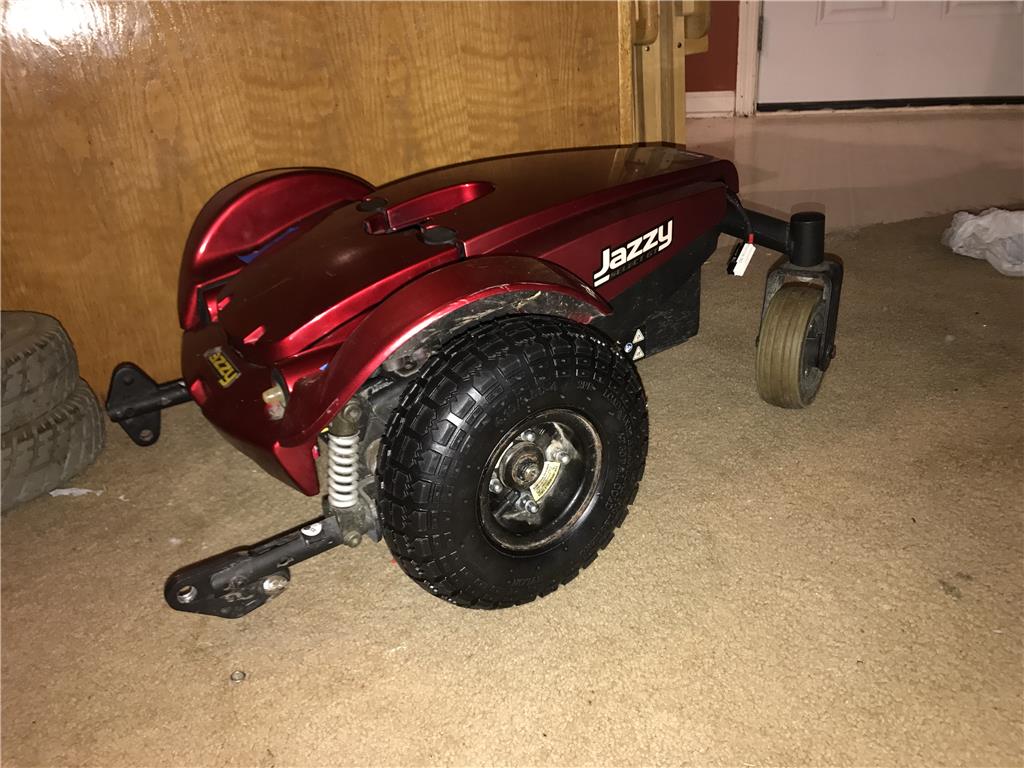
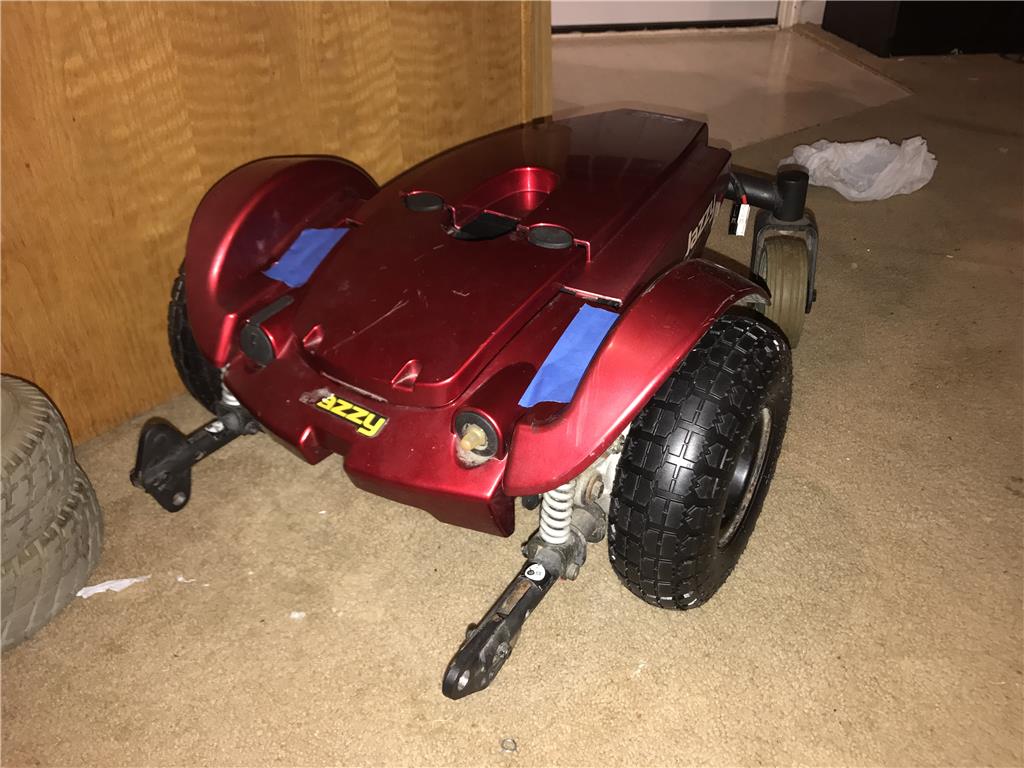
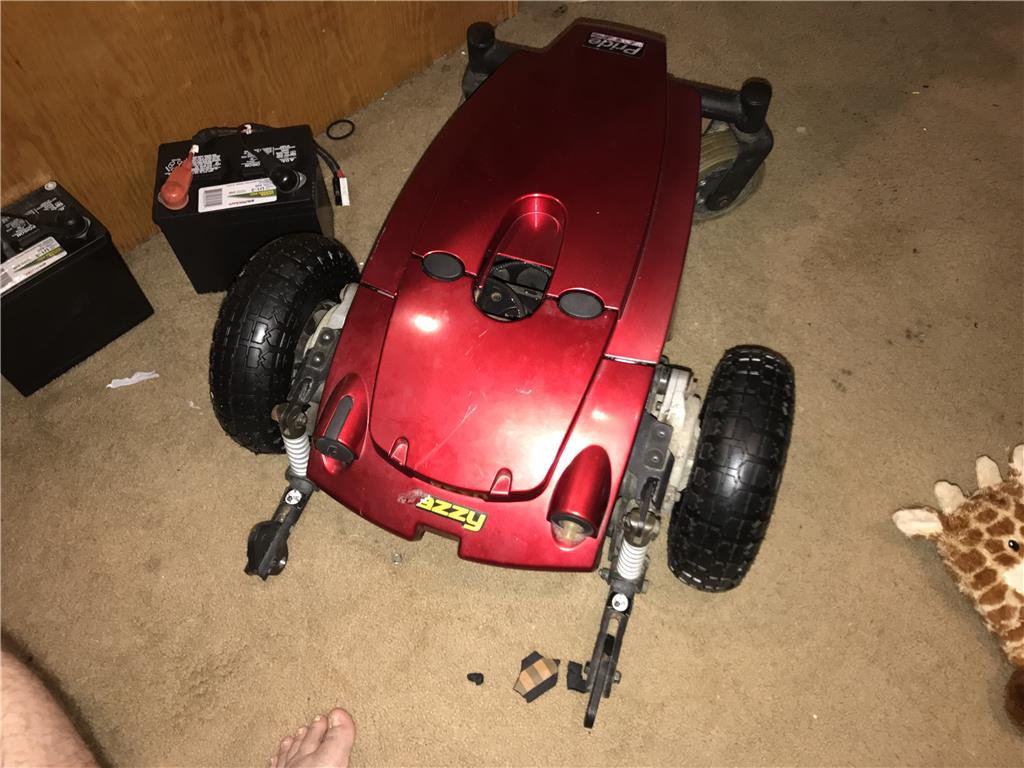
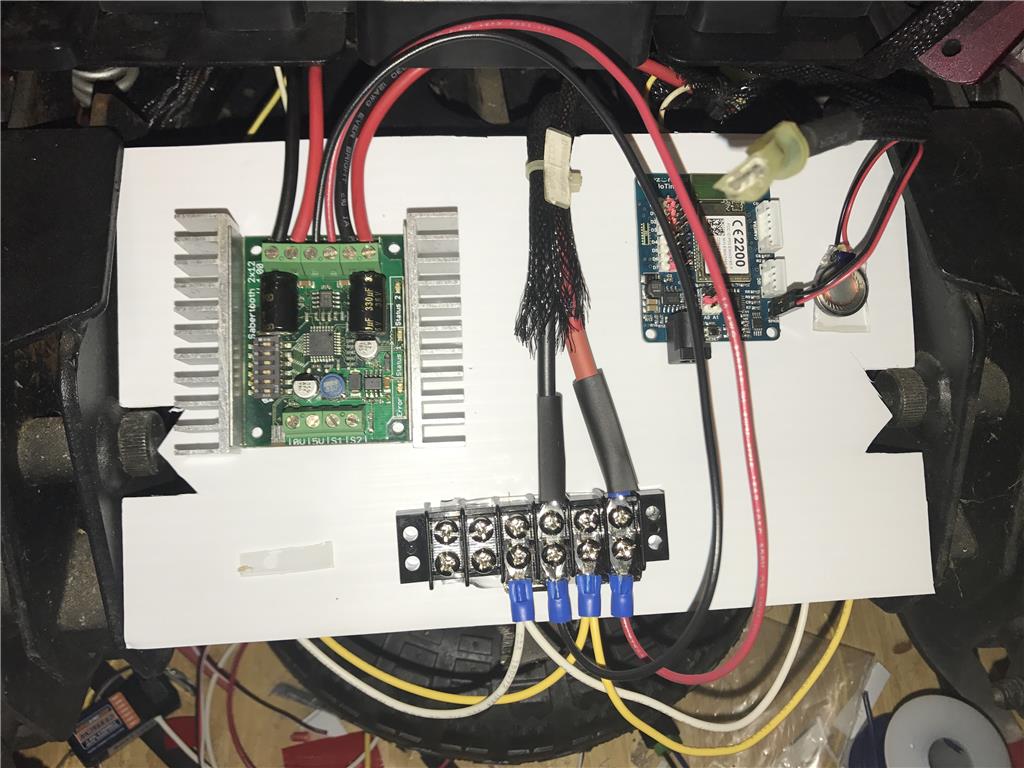
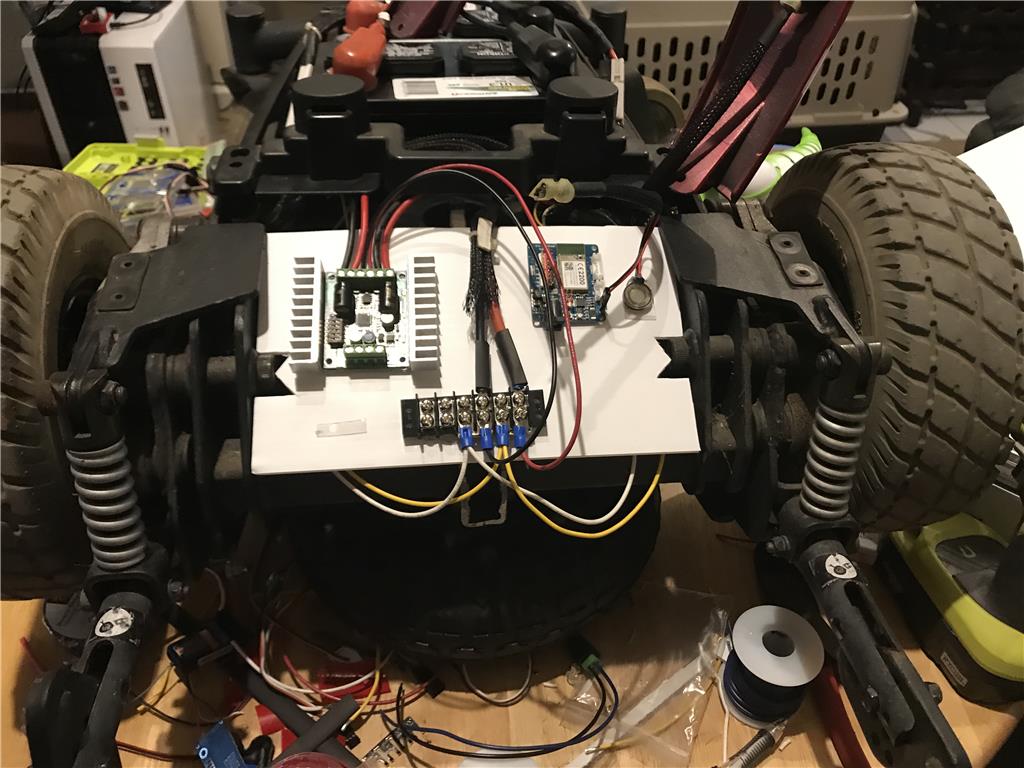
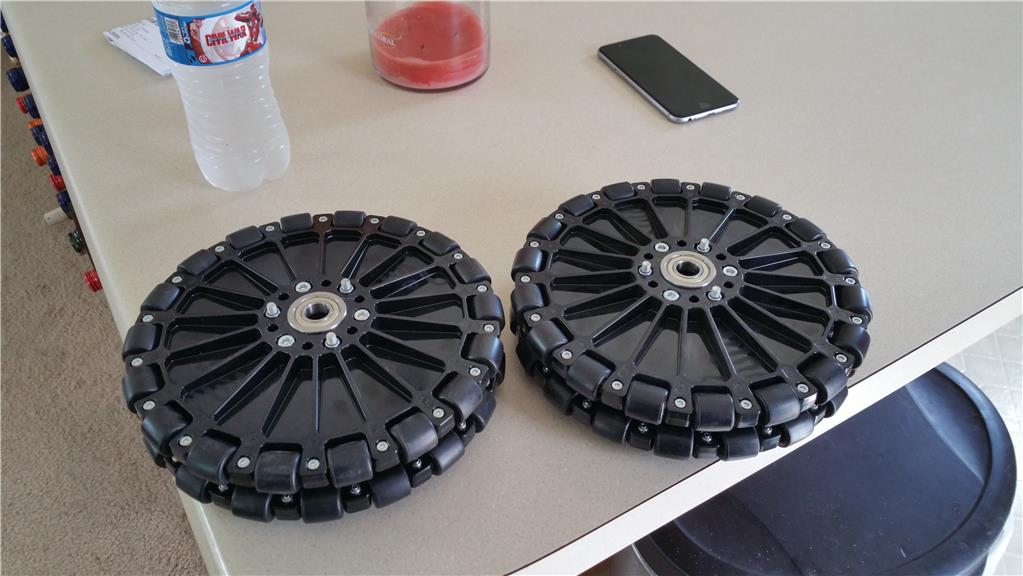
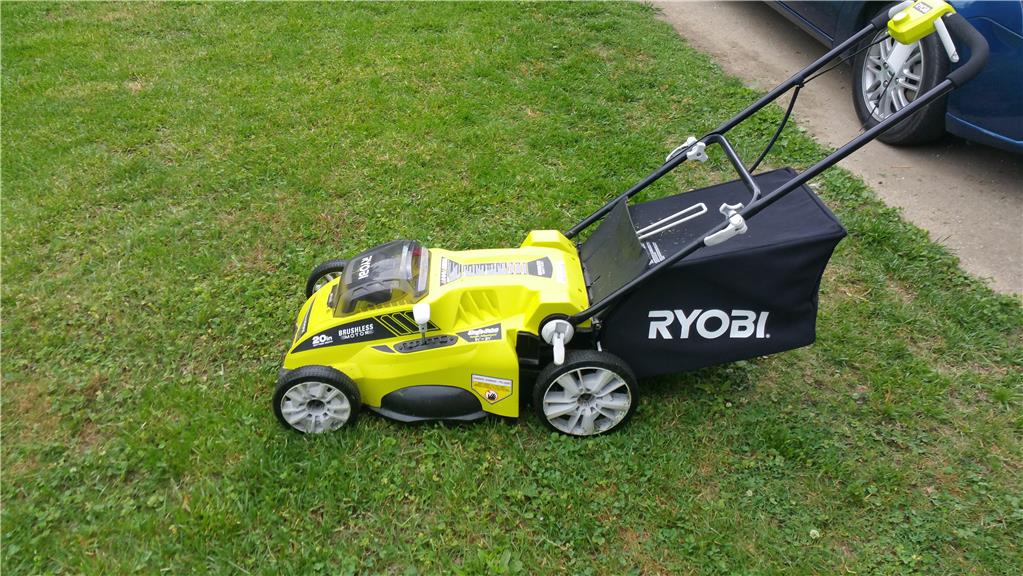
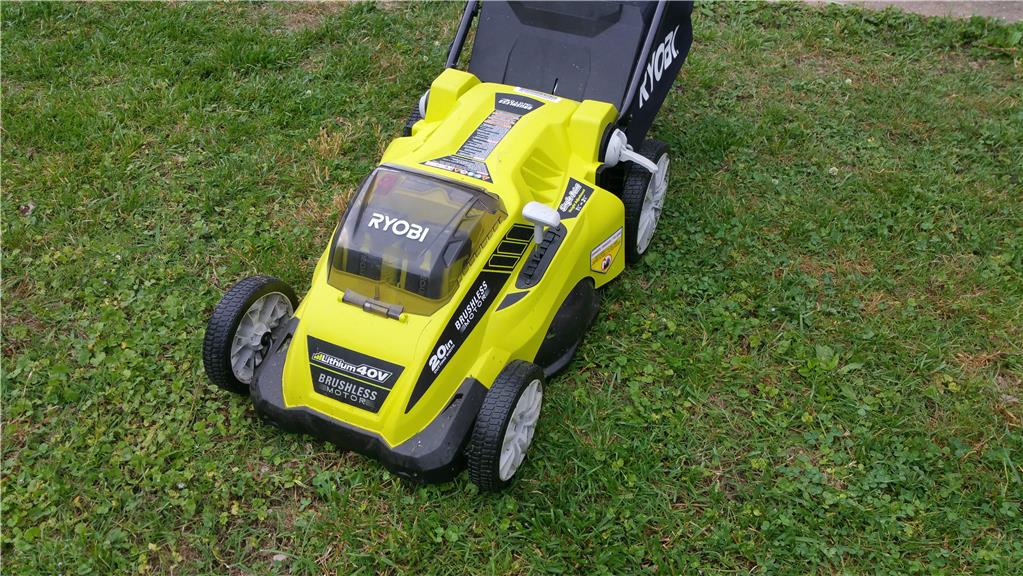
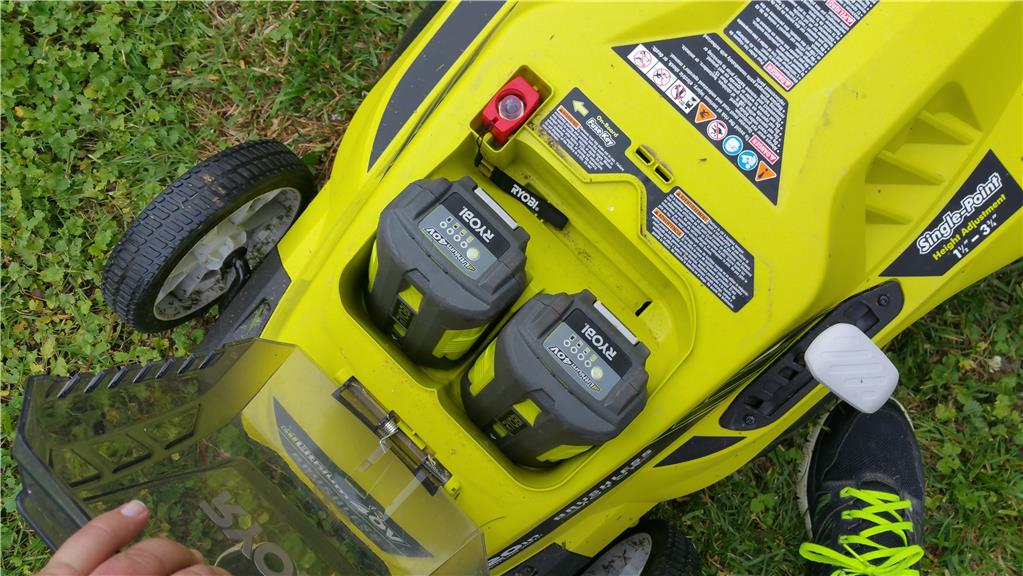
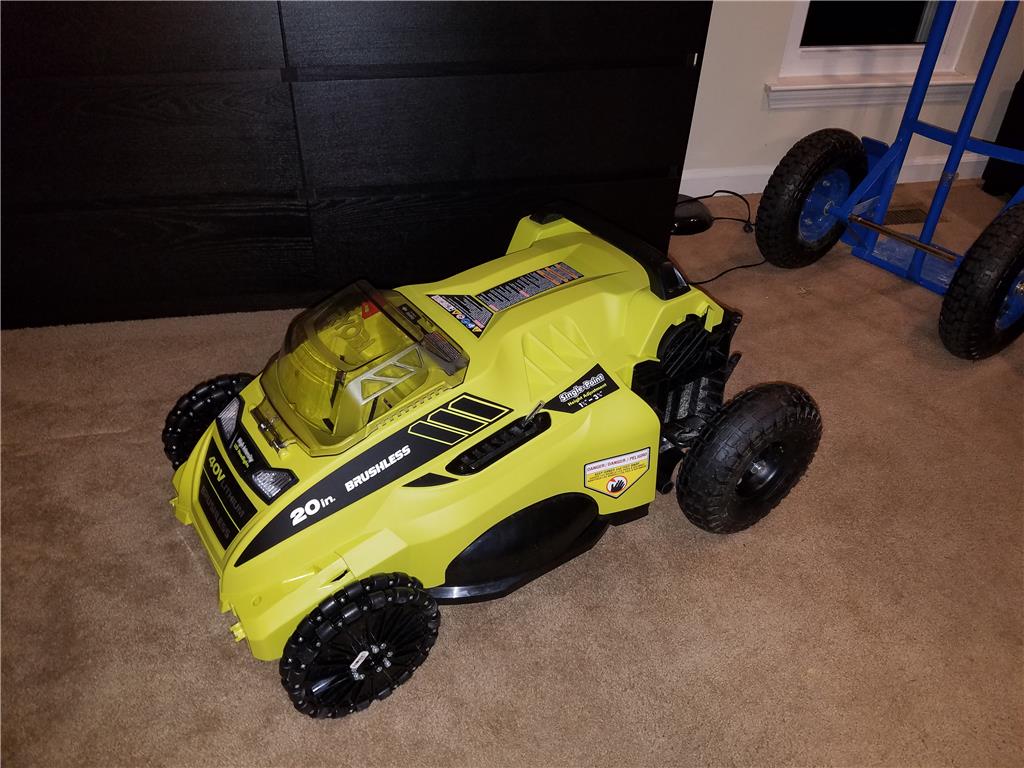
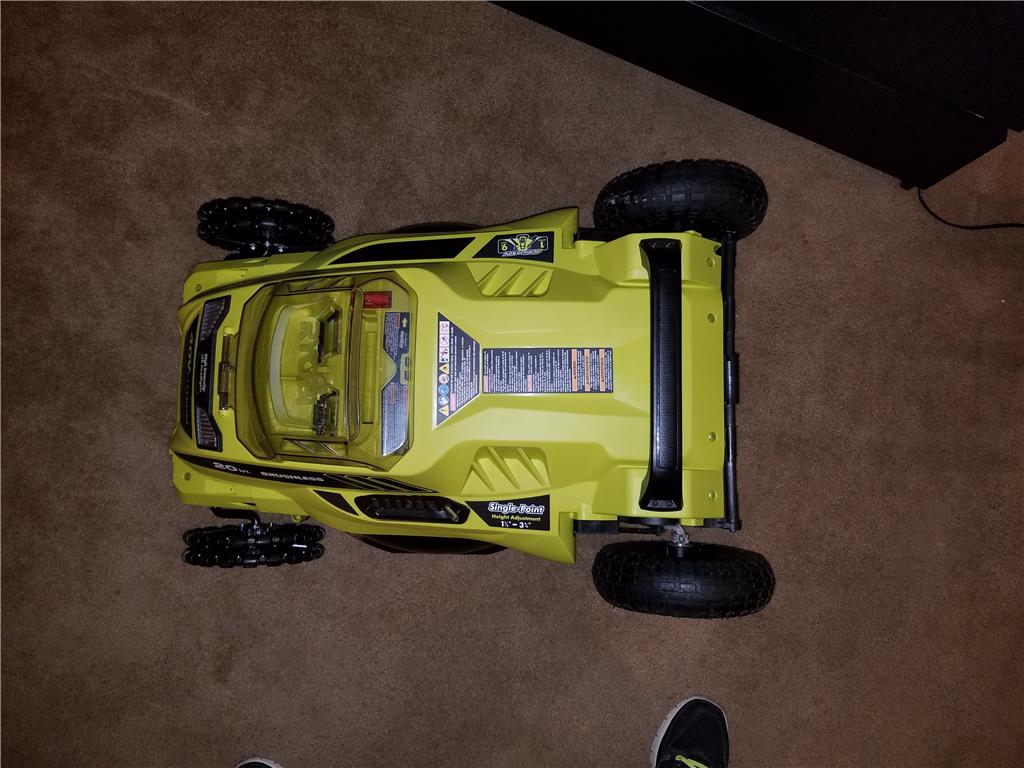
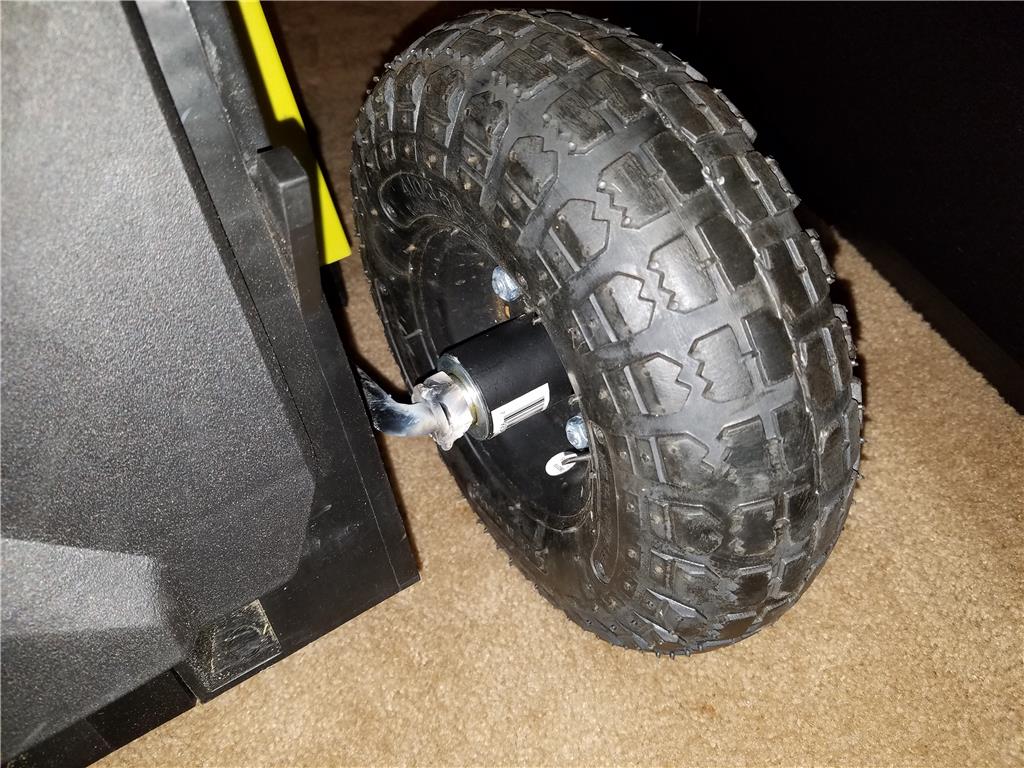
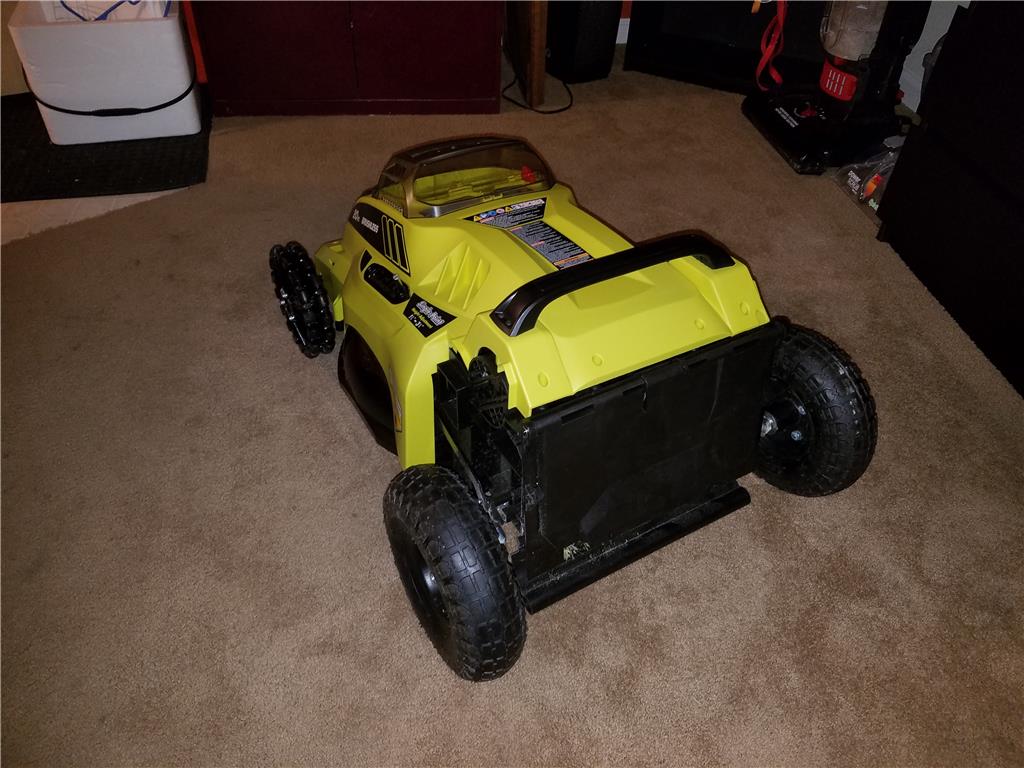
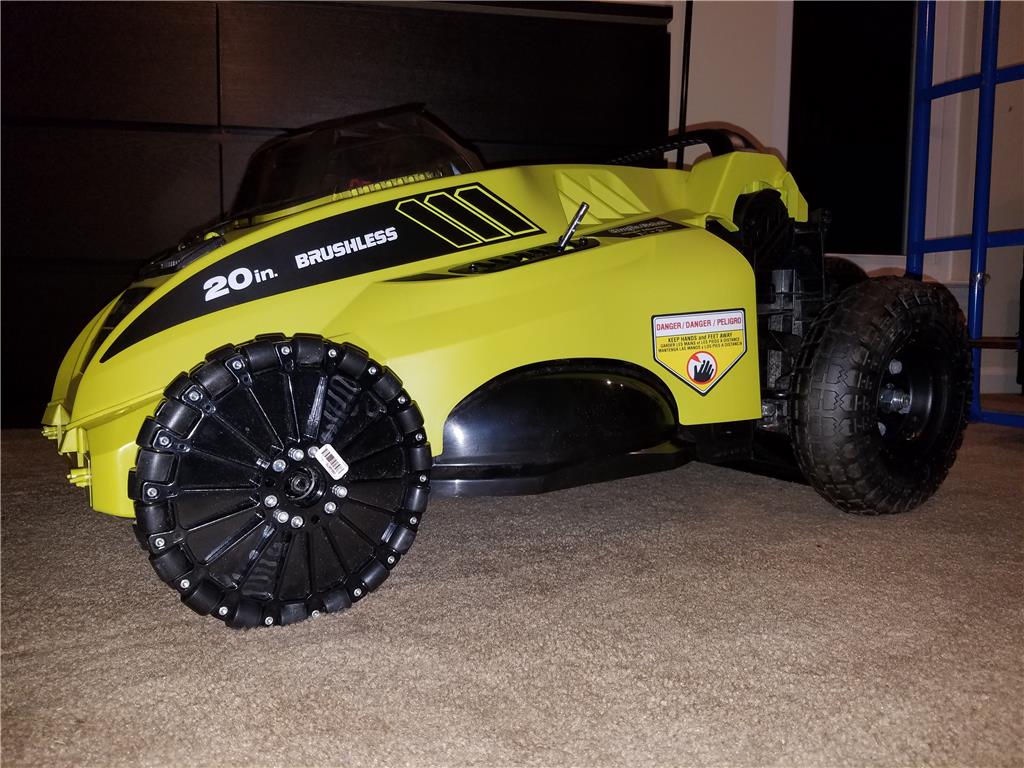
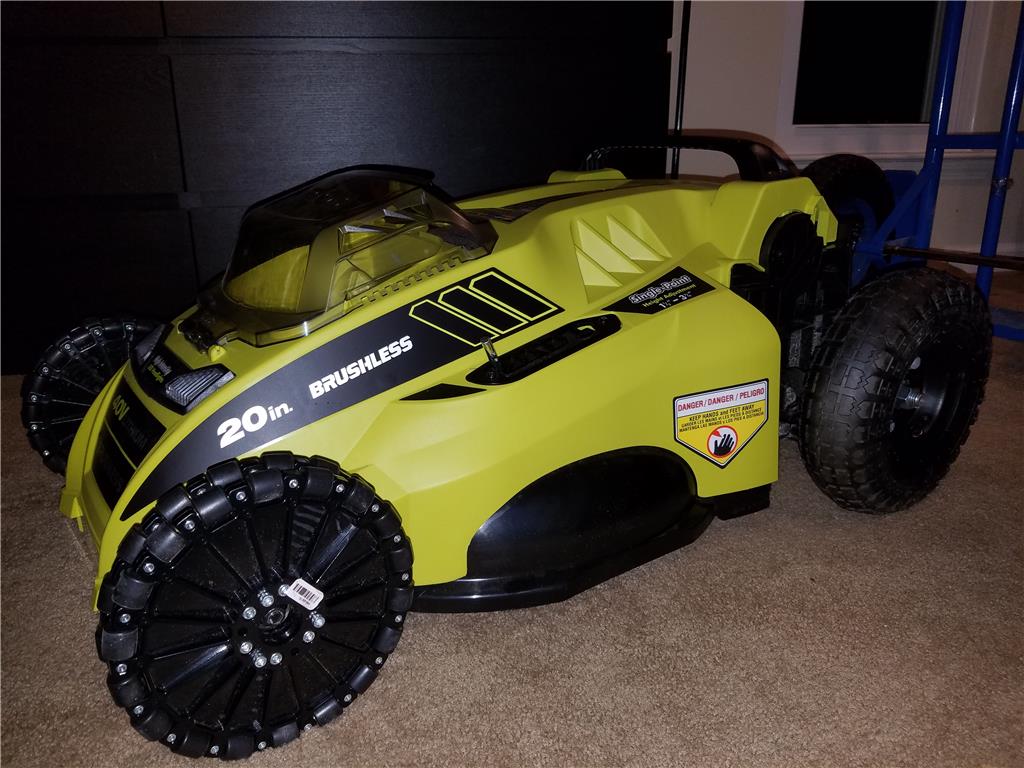
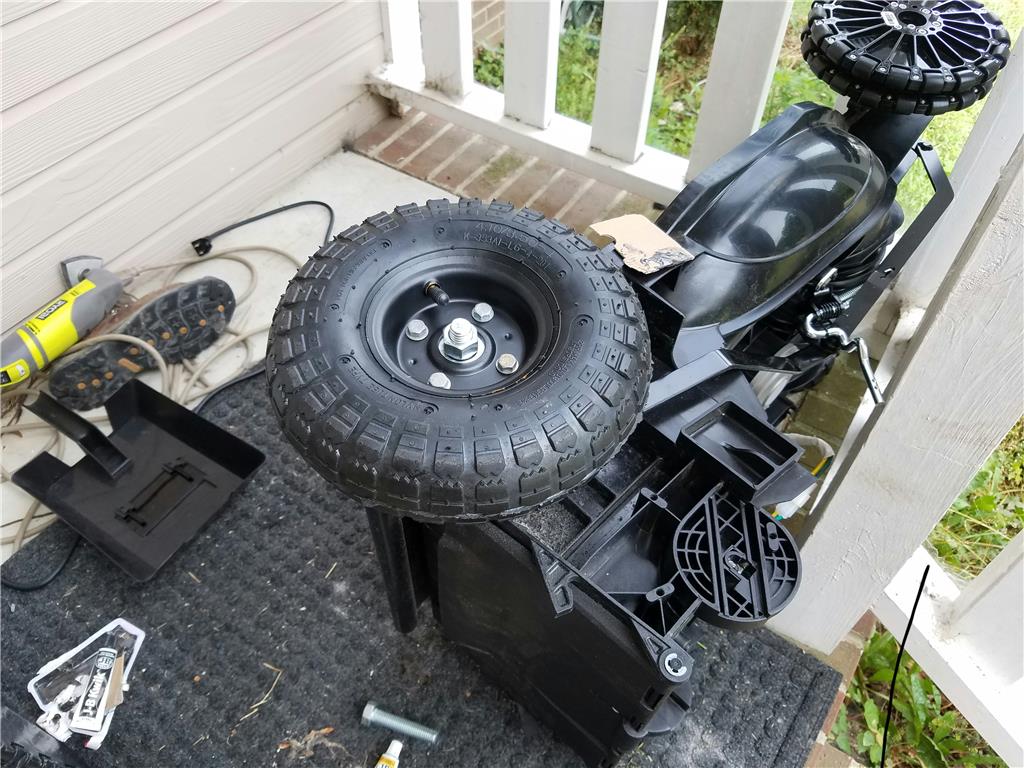
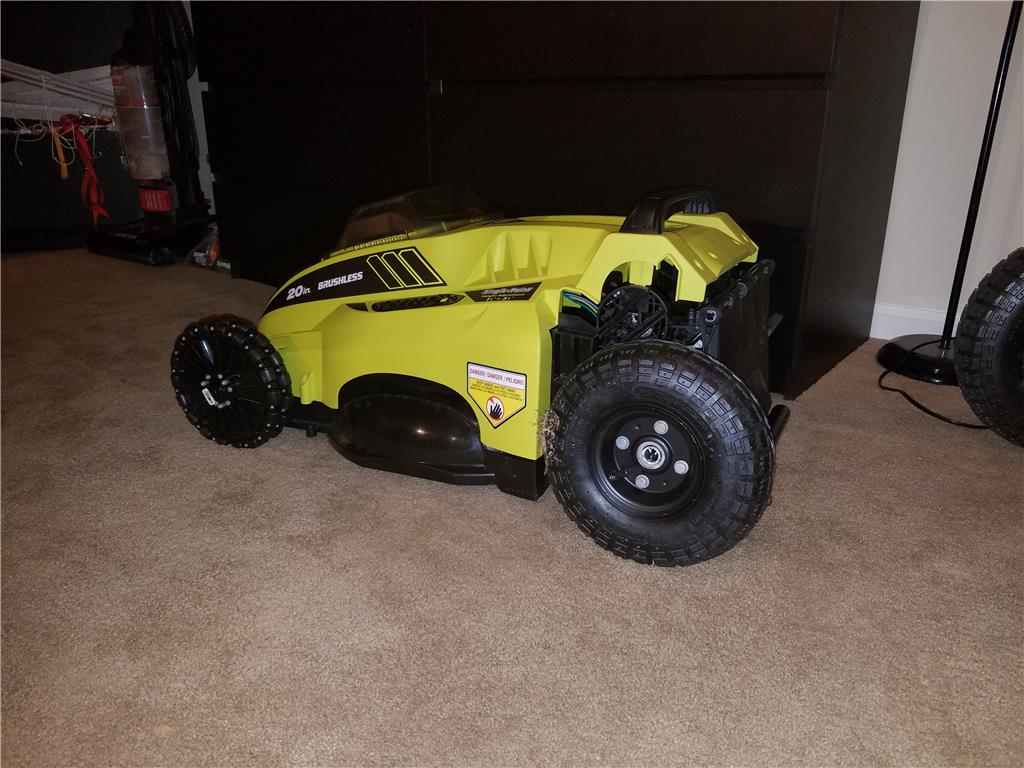
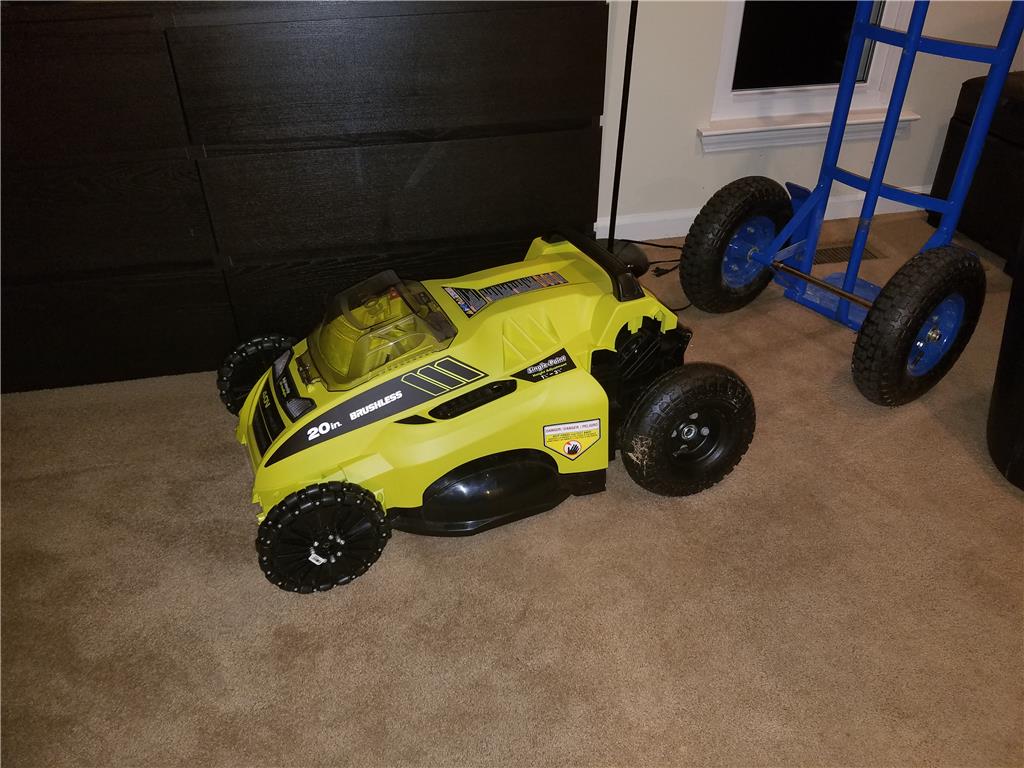
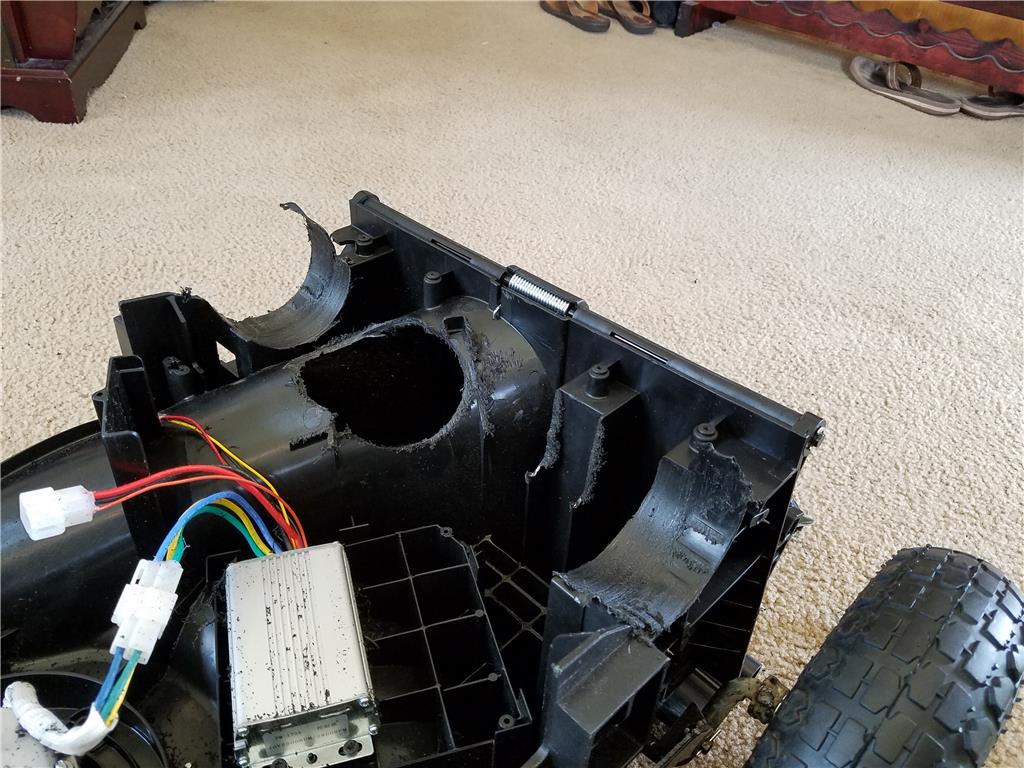
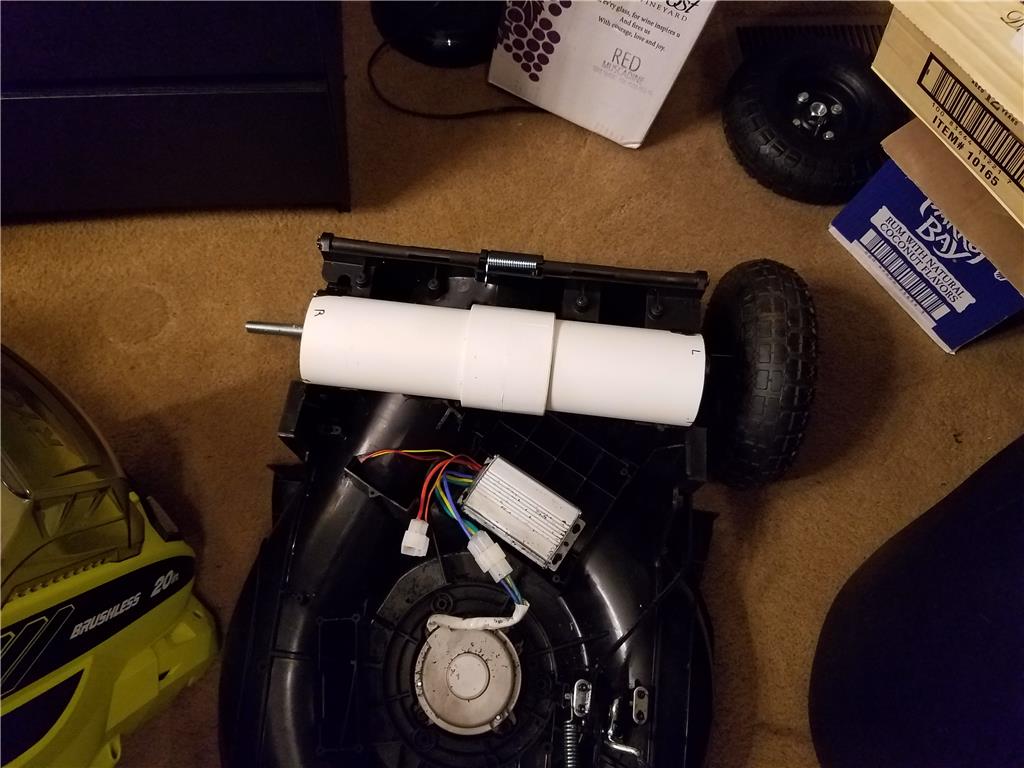
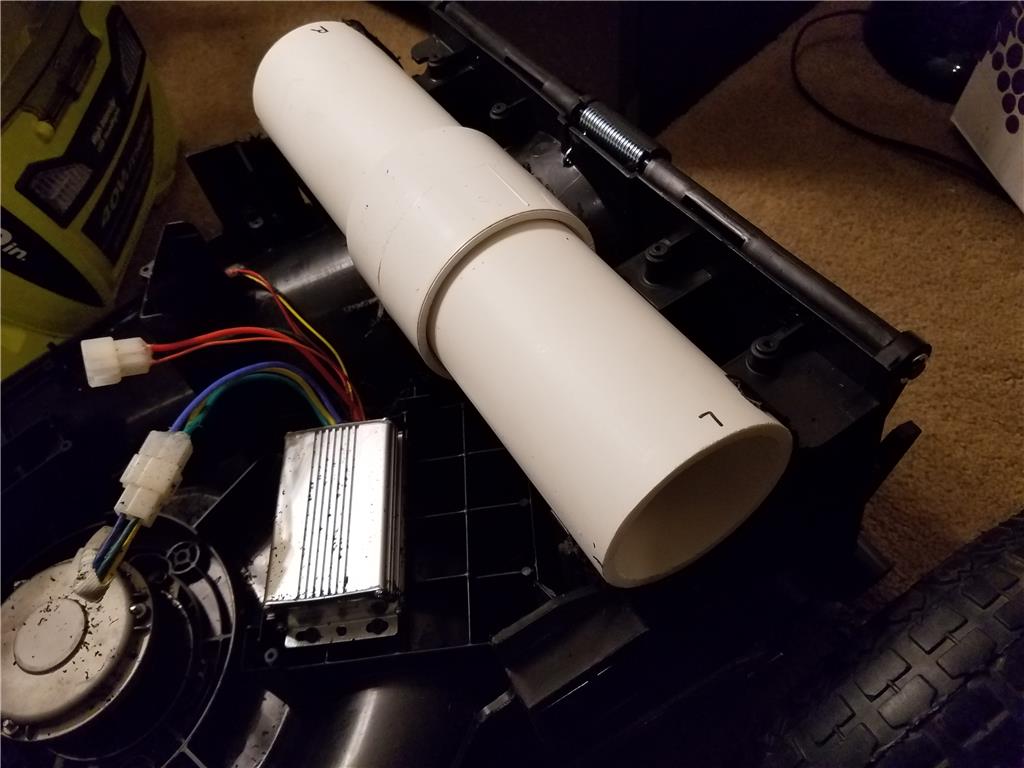
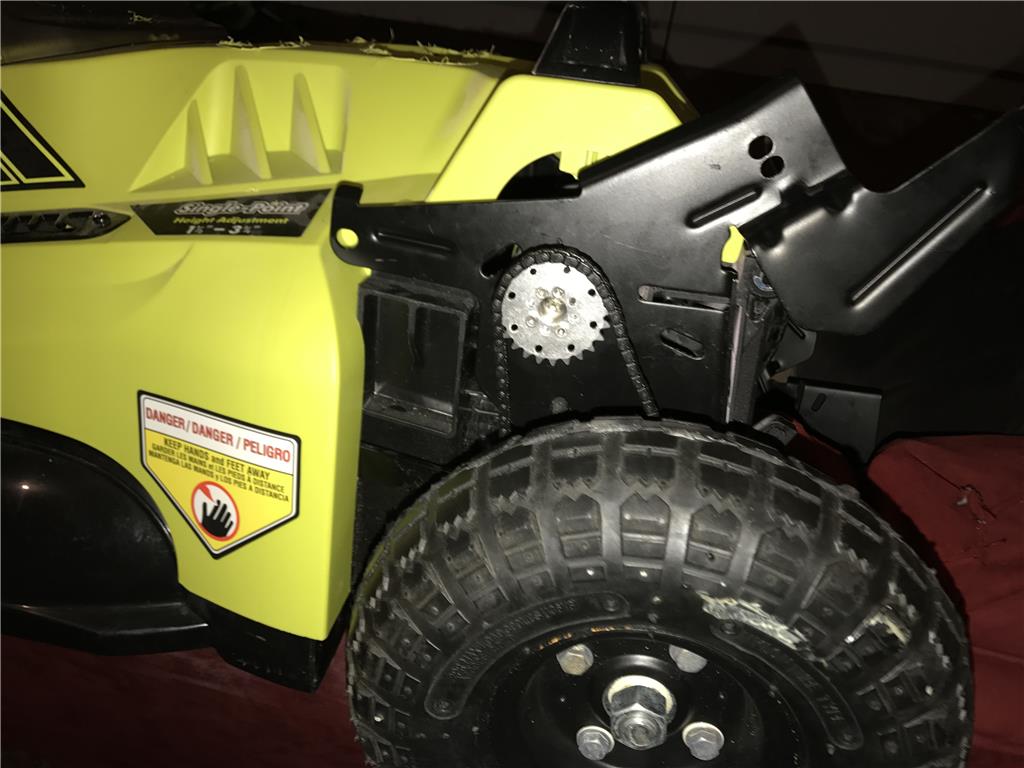
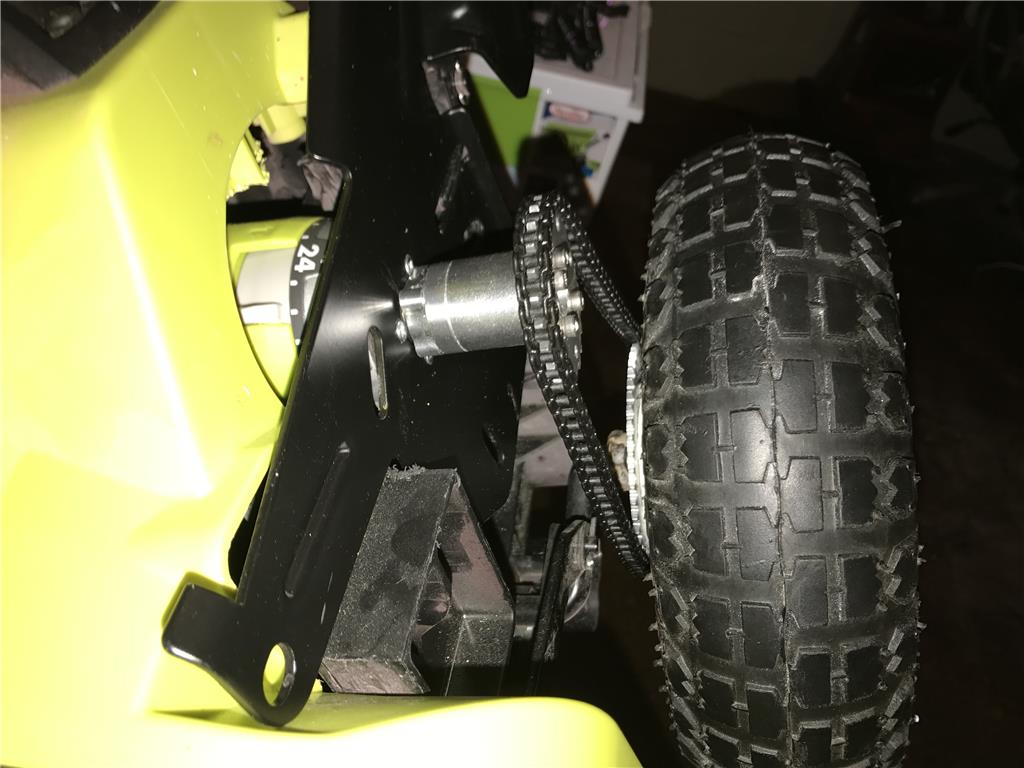
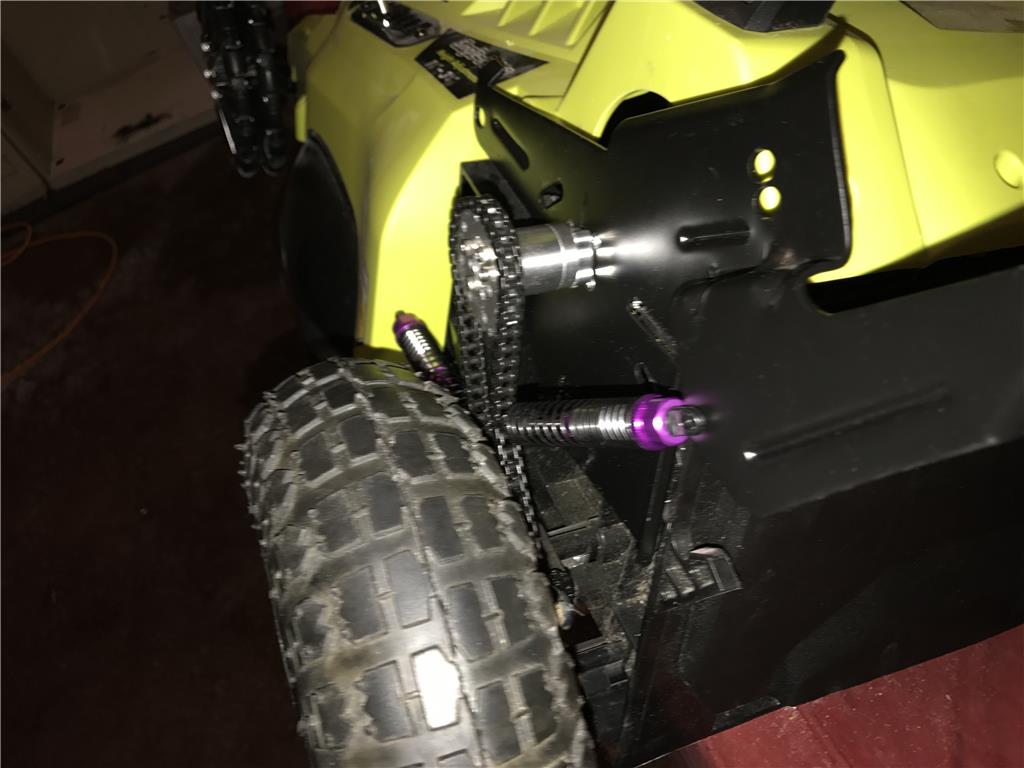
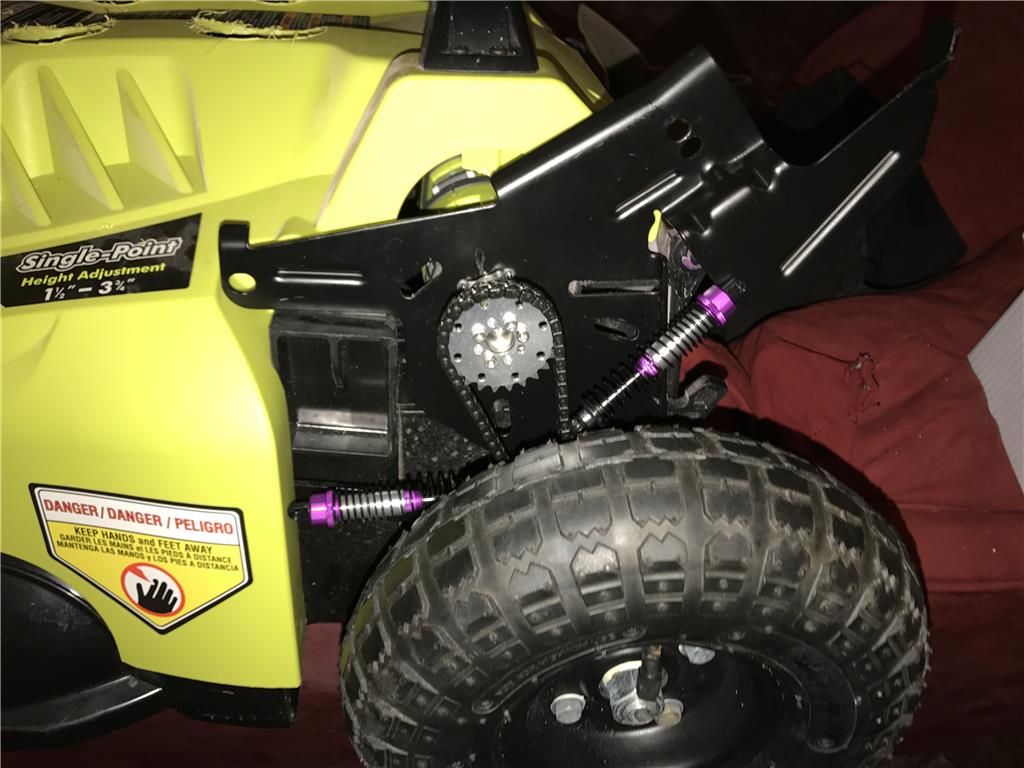
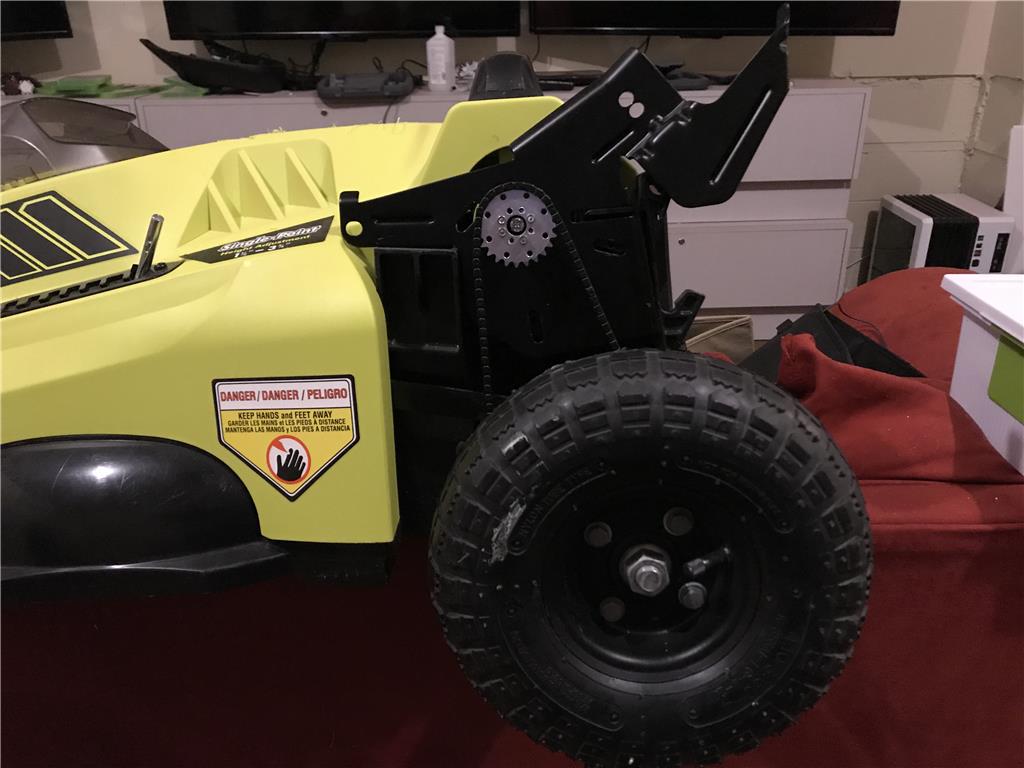
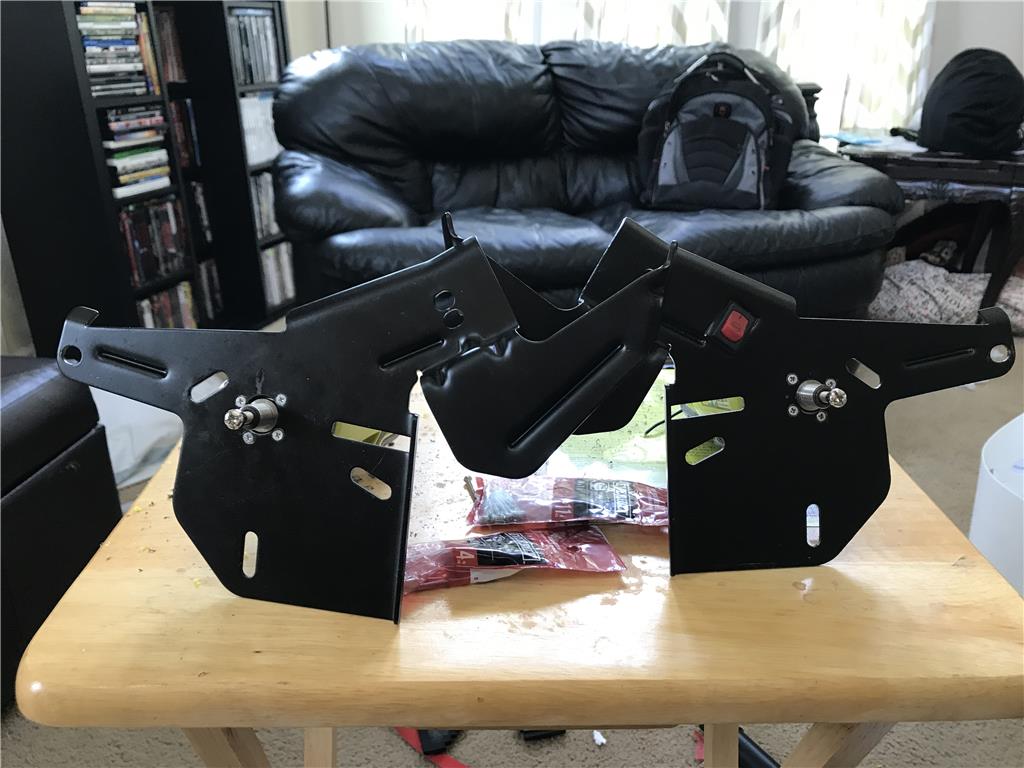
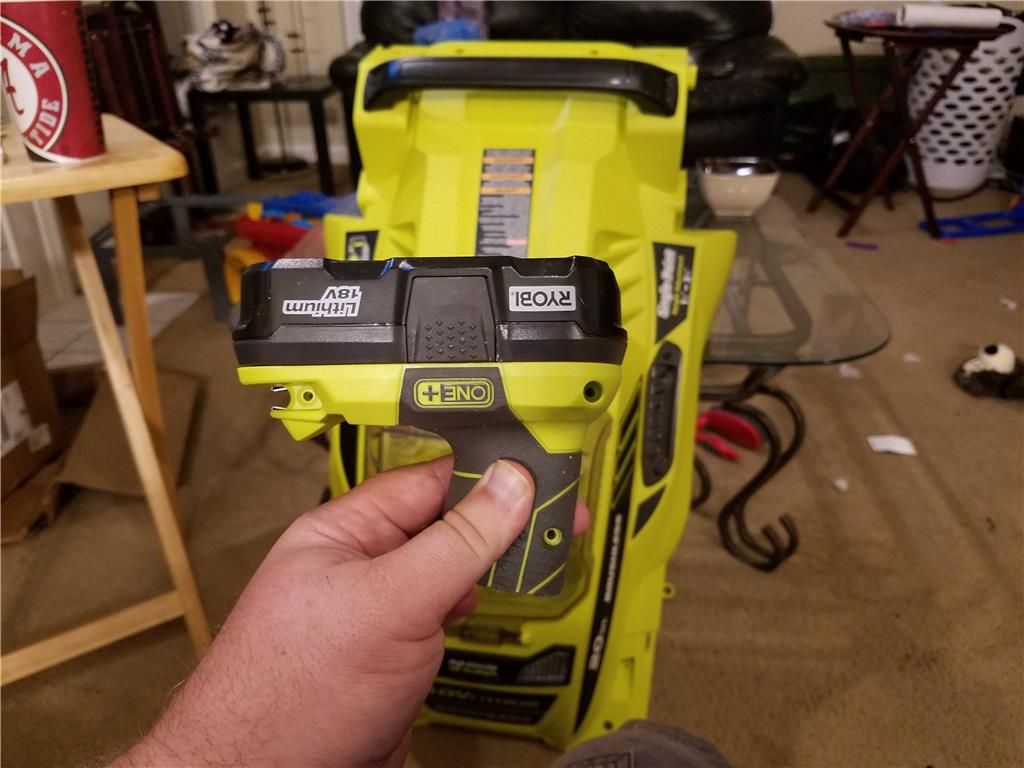
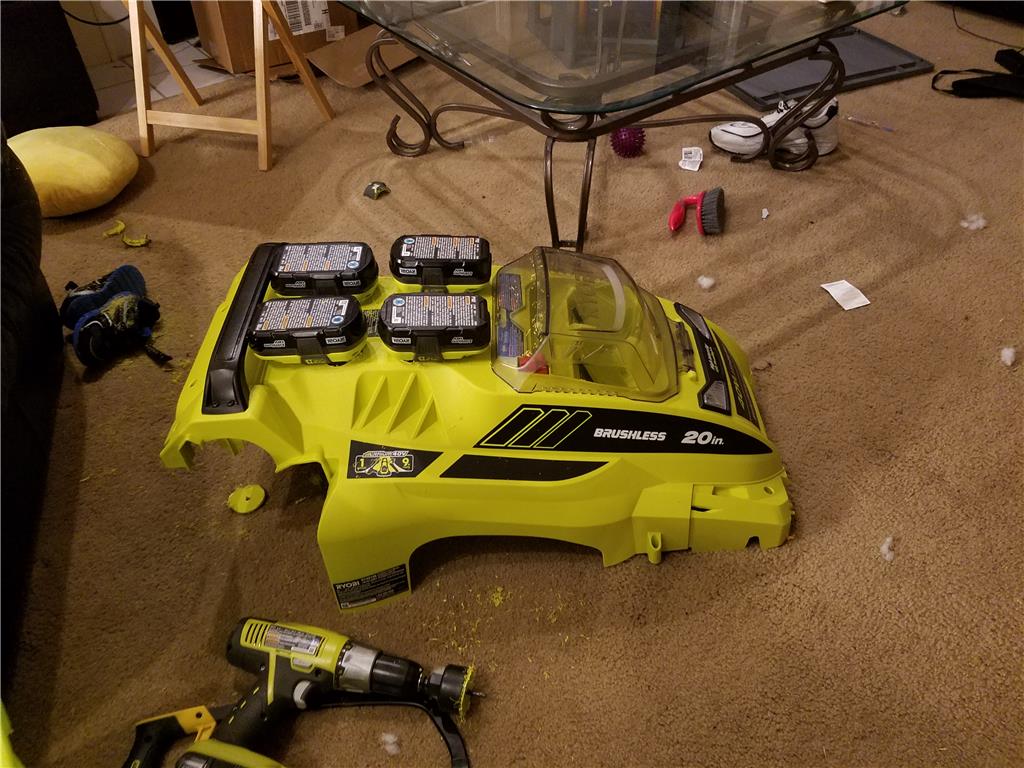
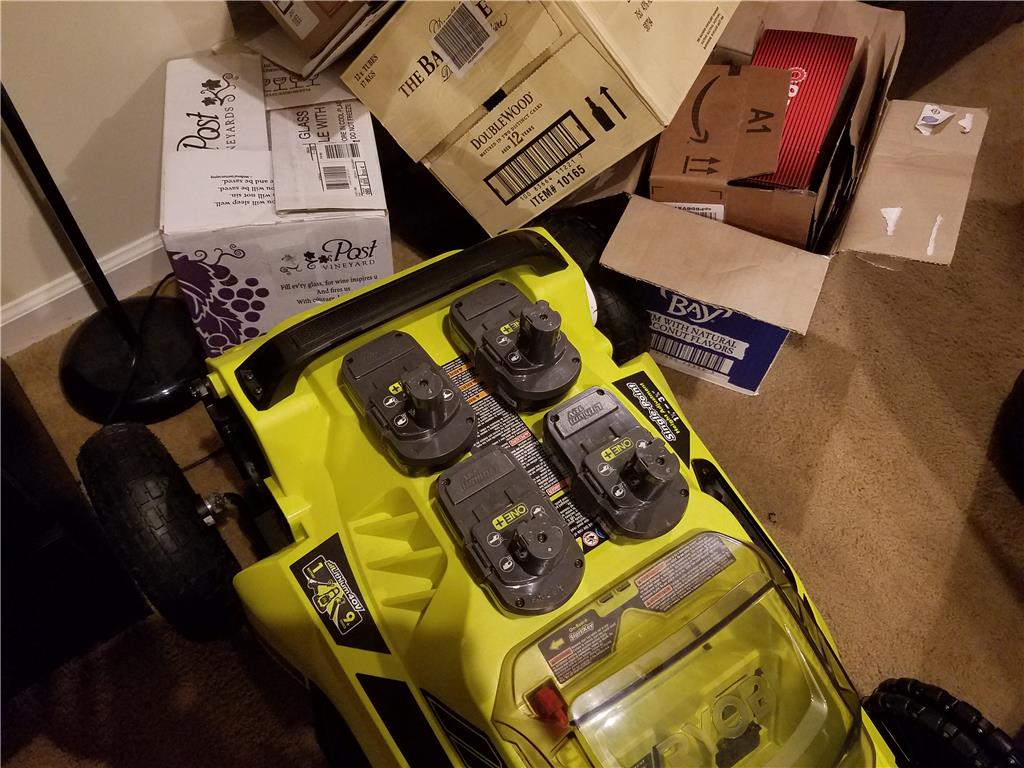
Hello all, I am getting back in the saddle making robots now that I am moved into my new home and settled into my new job as a technician maintaining the Fiber Optics network in Chattanooga TN.
IM BACK !
By jstarne1
— Last update

Discover more robots
Ezang's Beginning 3D Printed Hand, Some Moves - Voice...
New hand project needs rework with better string, other commands and tips pending; still many tasks and development work...
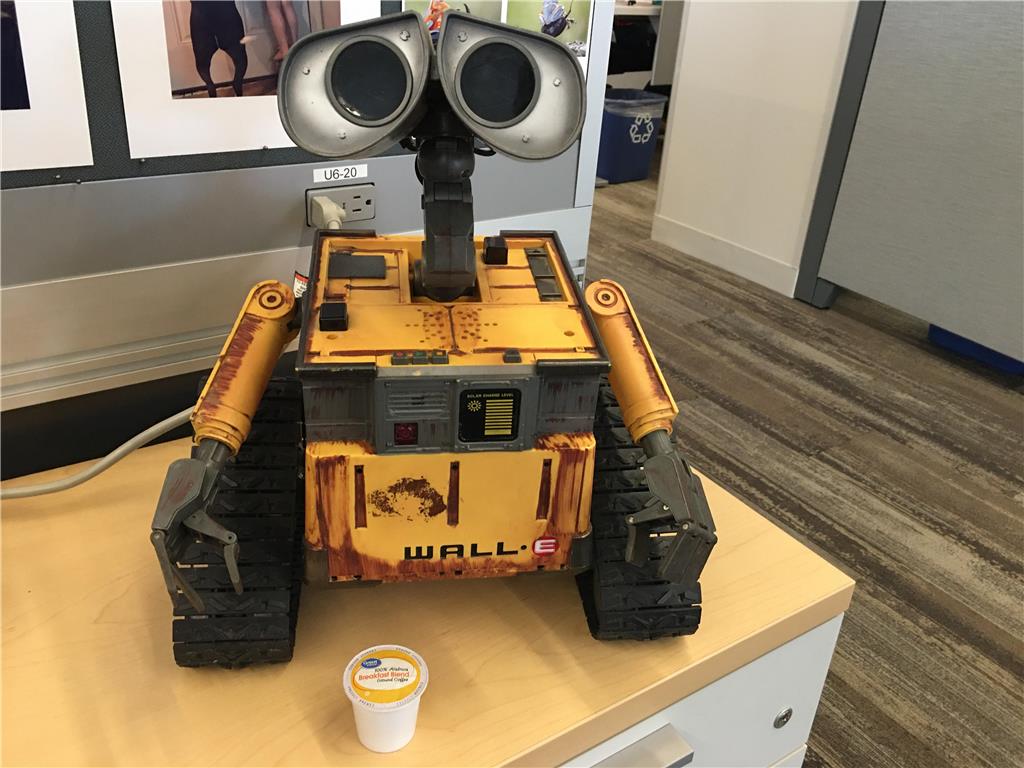
Jstarne1's 4 Sale- RARE HUGE Ultimate Wall-E. Excellent For...
Ultimate 20-inch 2/3-scale Wall-E - $250. Cleaned, 80% of actions via onboard buttons or voice commands; no remote...
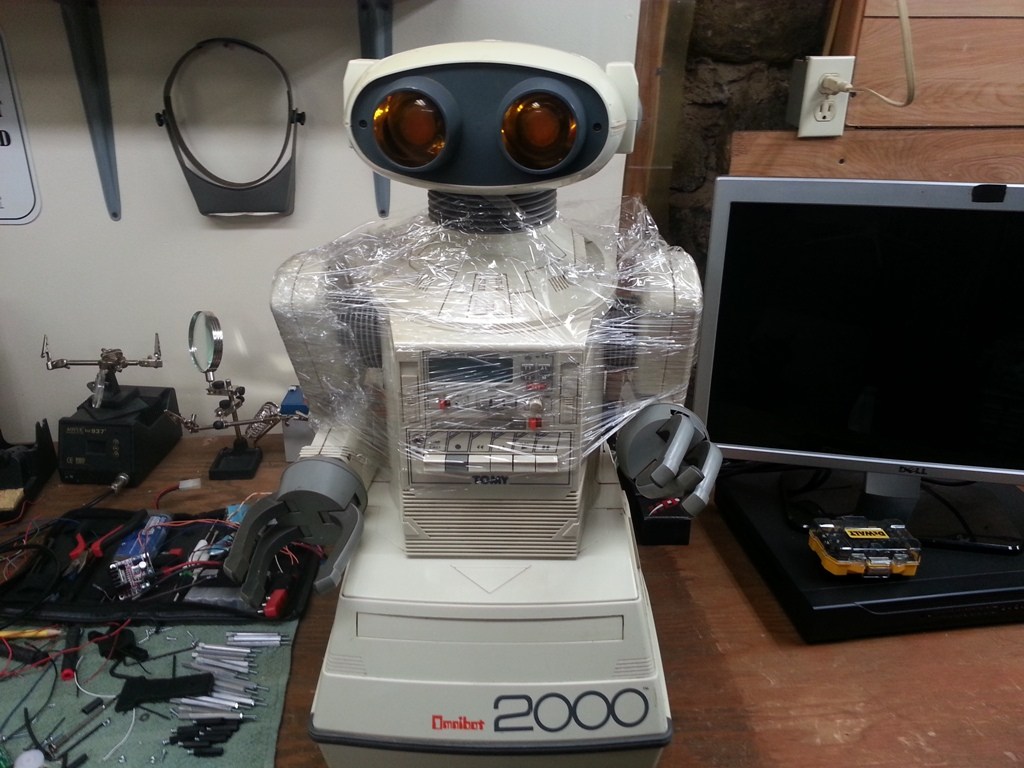
Charleybot's Project Multi-Omnibots 2000
Upgrade Omnibot 2000s with Mini-ITX PCs, 12V battery power, servo-replaced arms, L298 motor controllers, USB Lifecam...

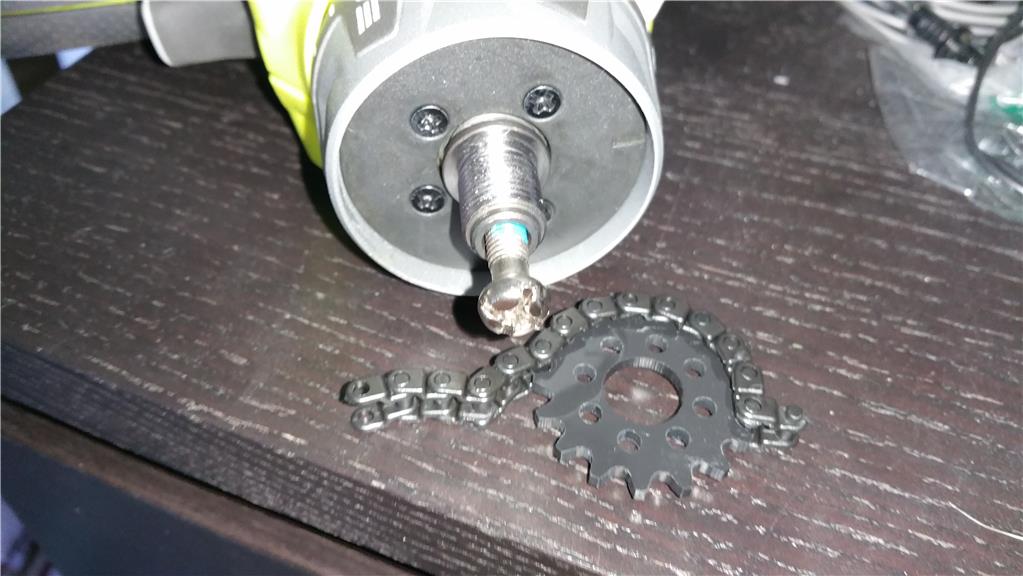
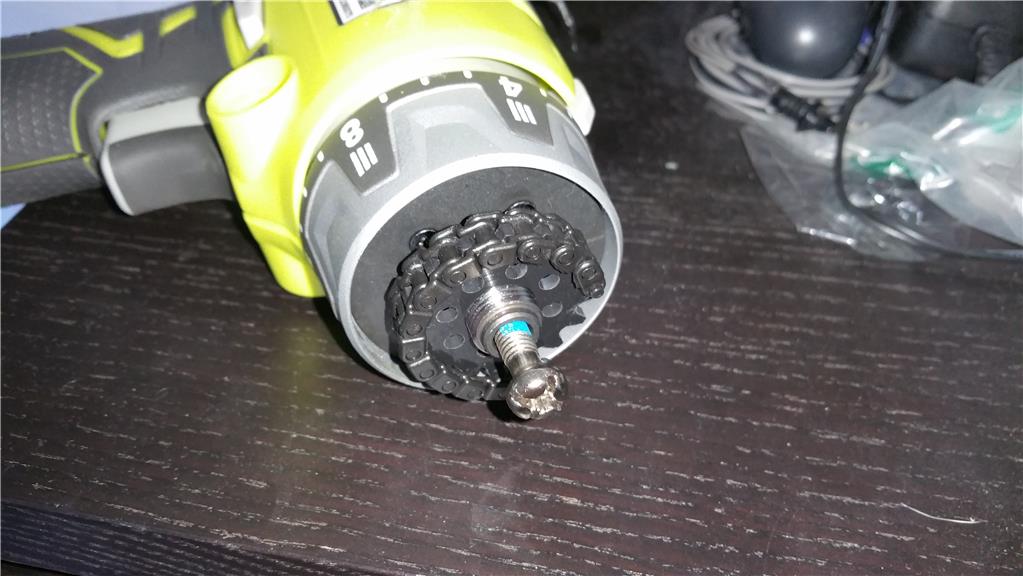
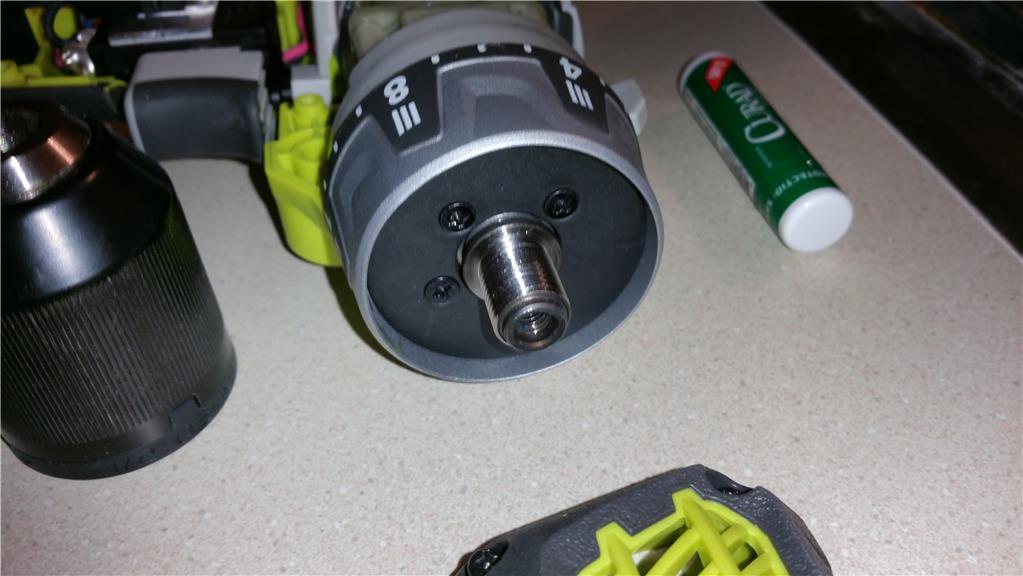
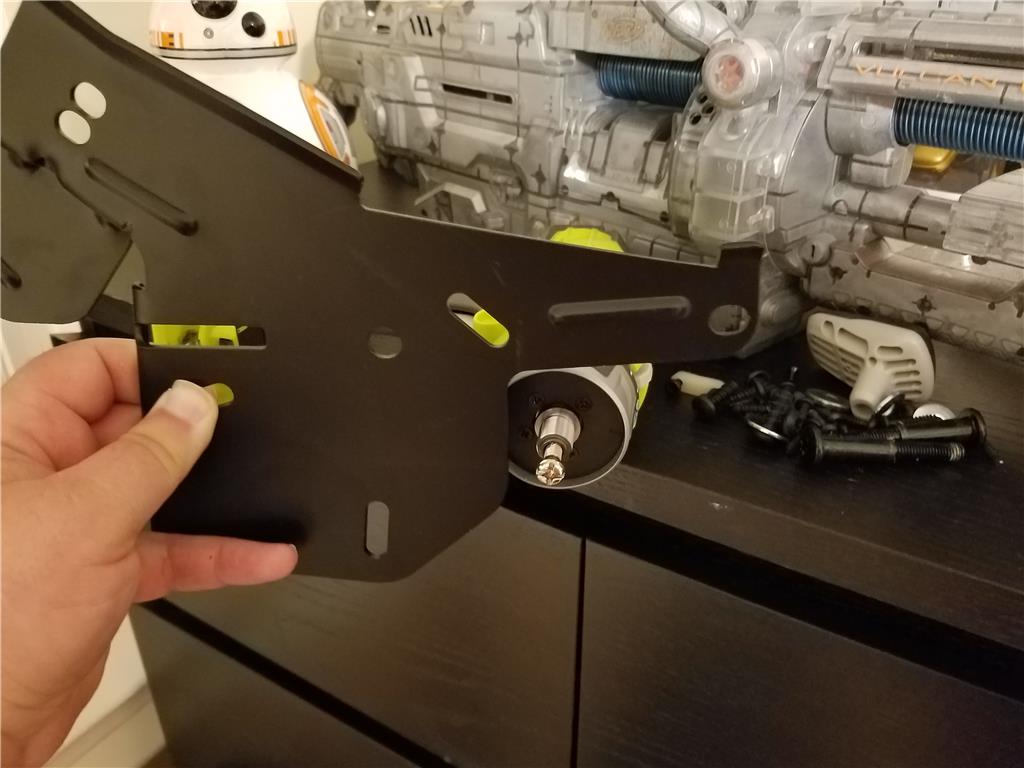
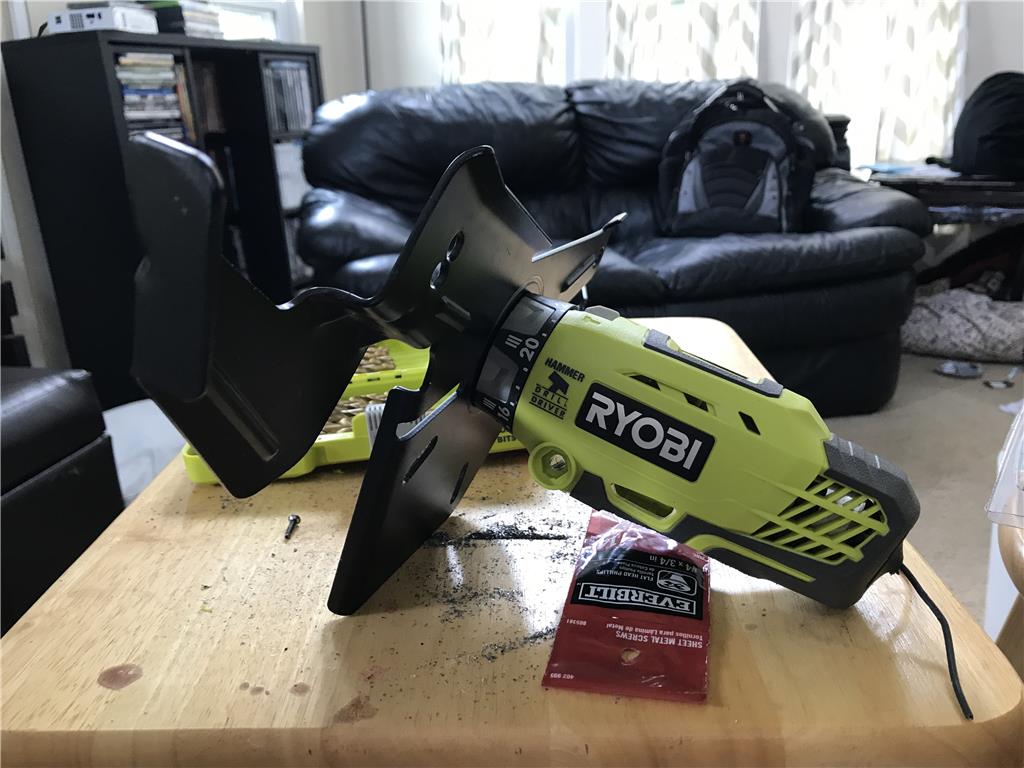
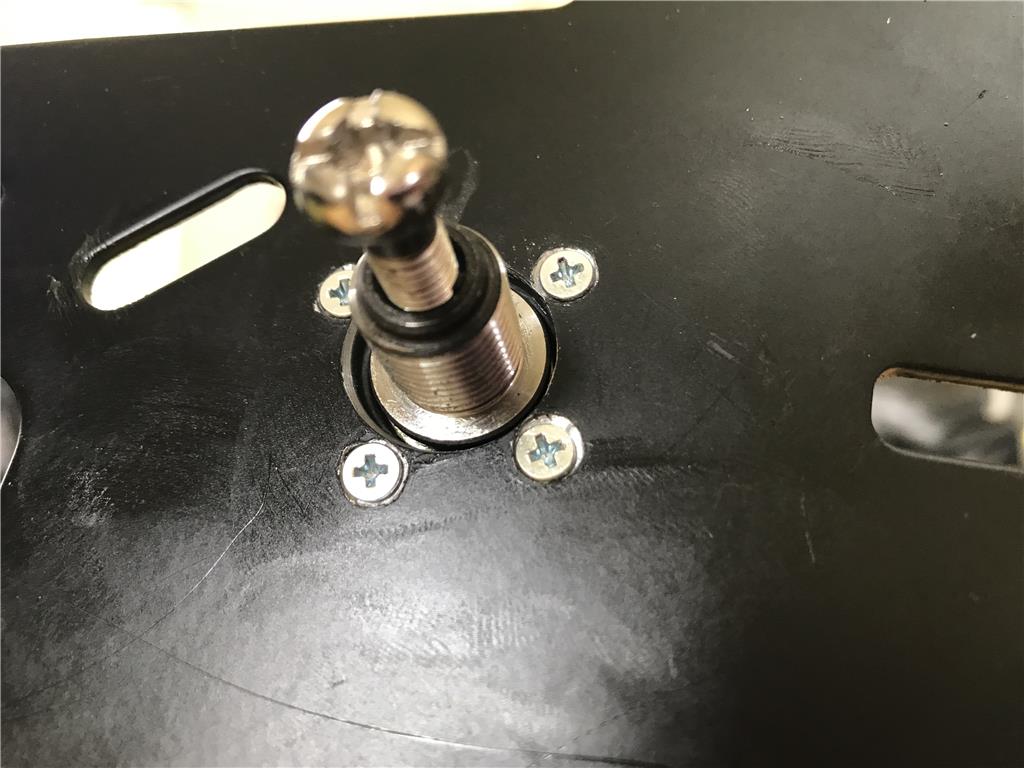
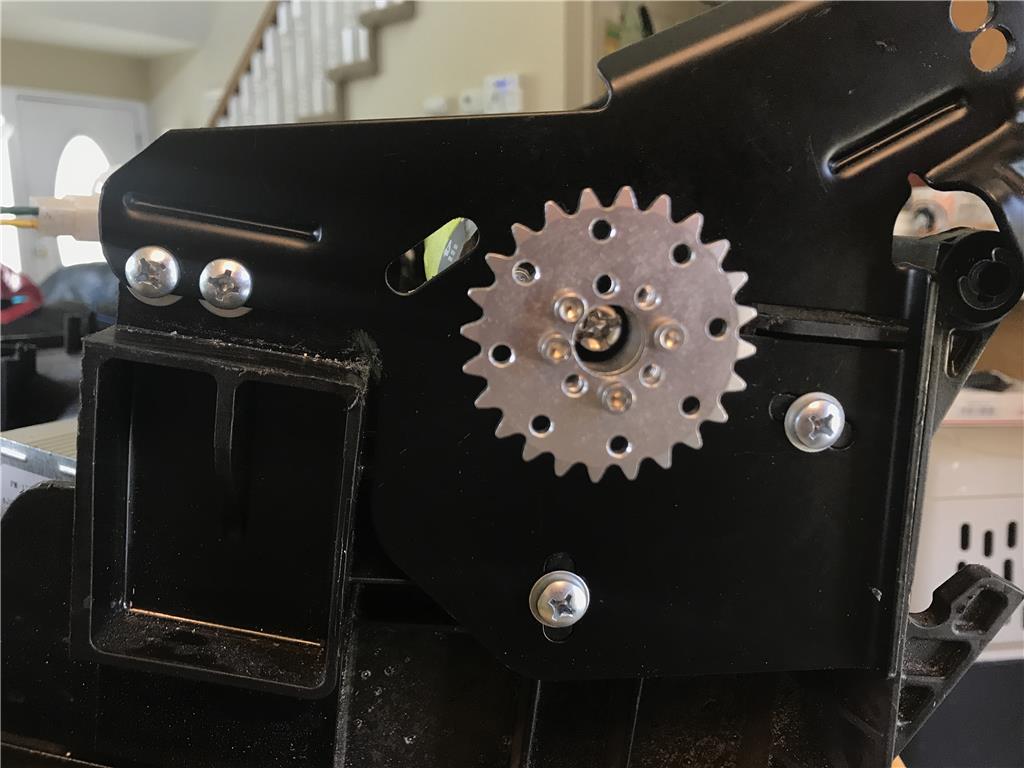
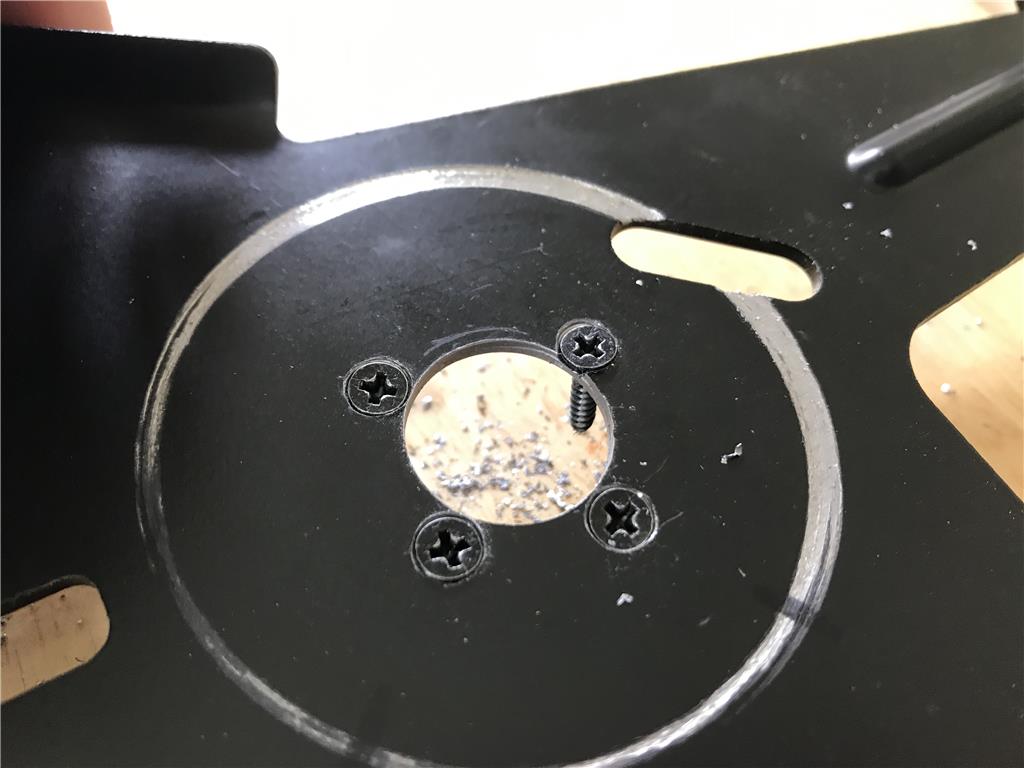
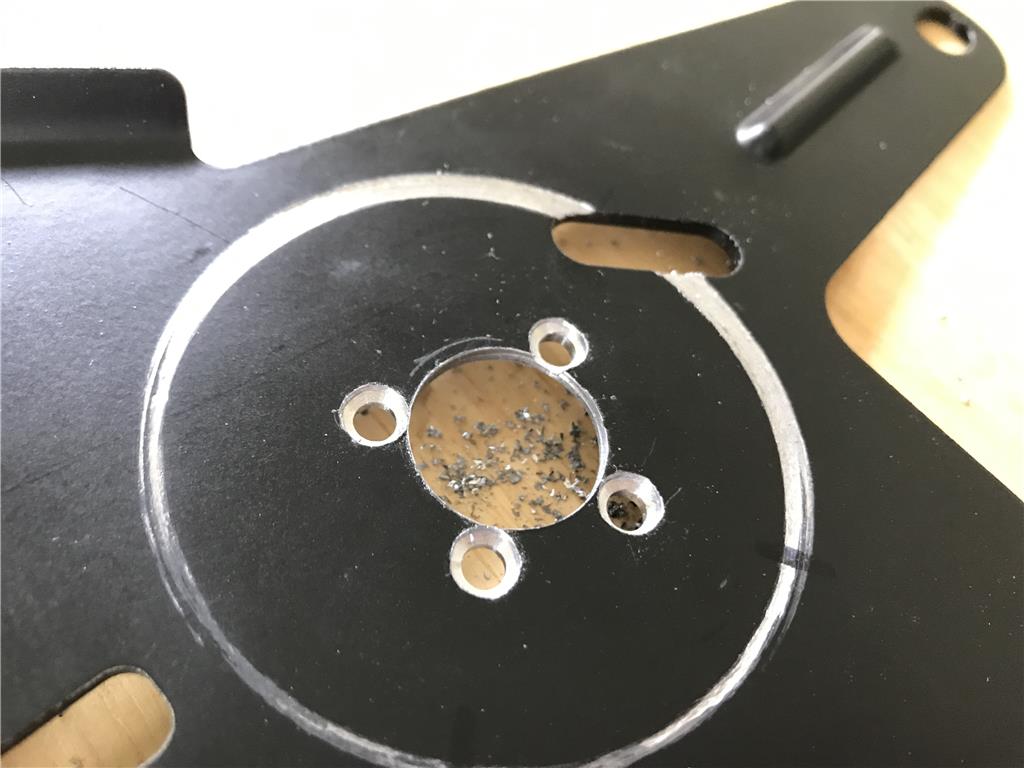
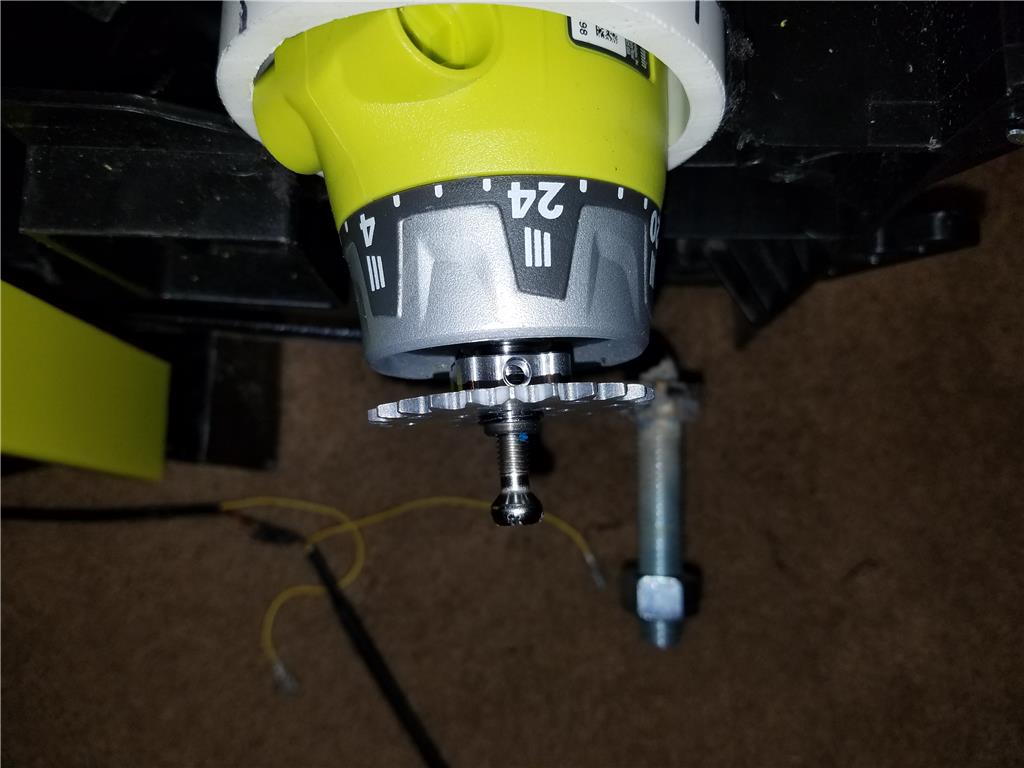
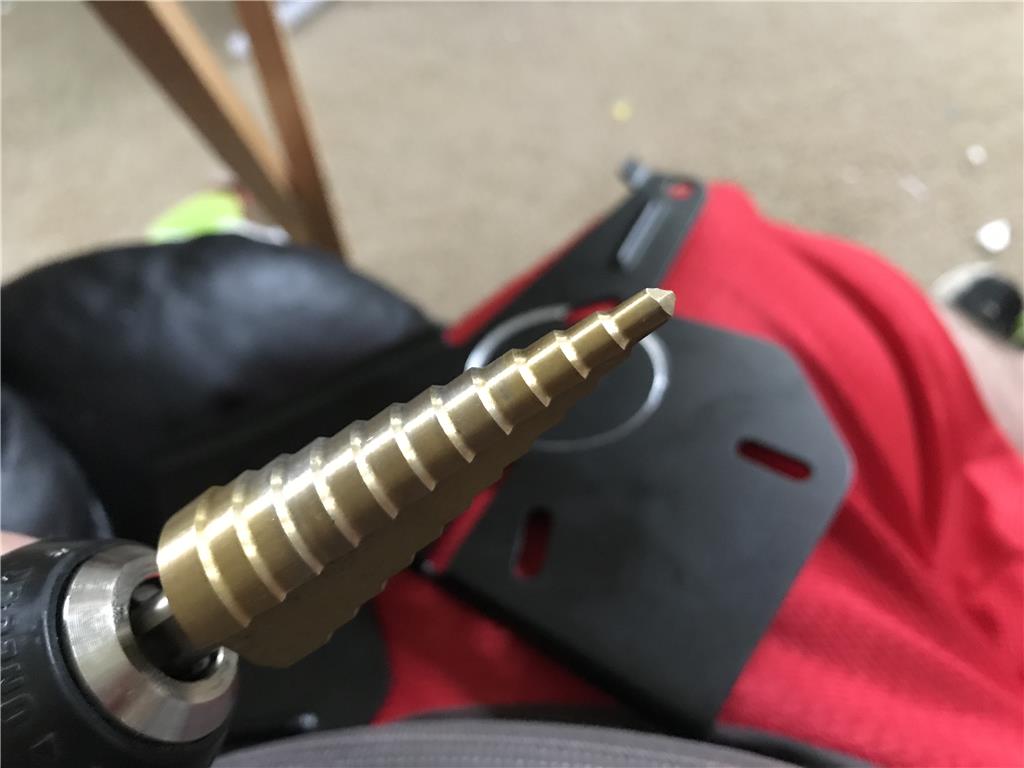
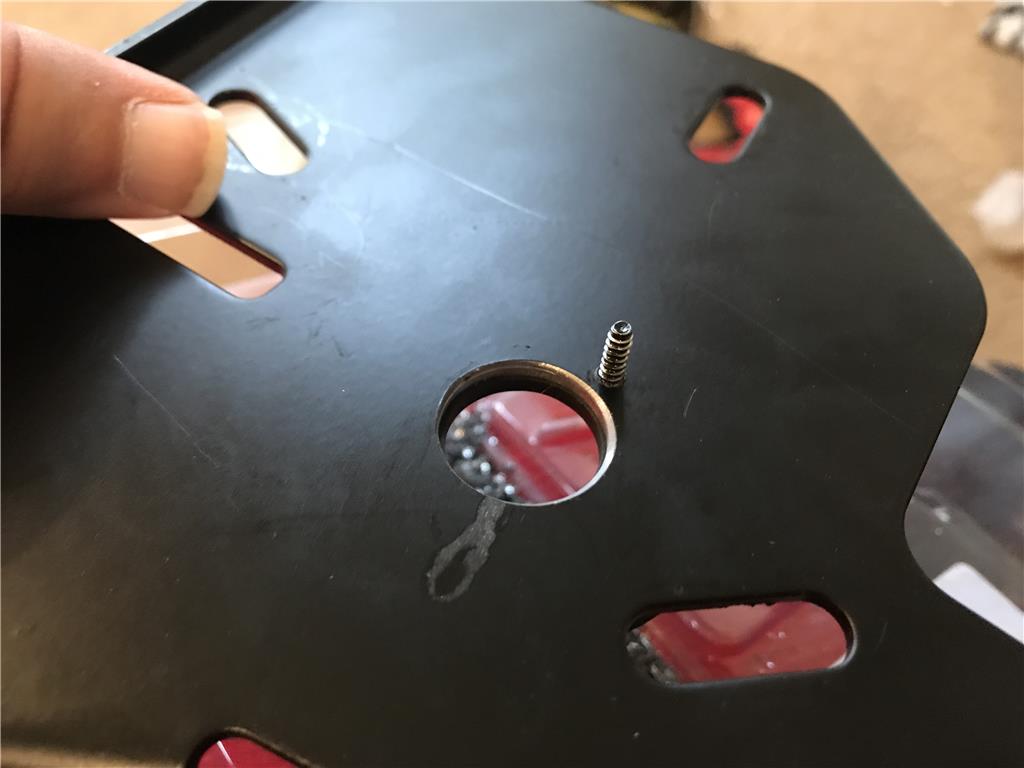
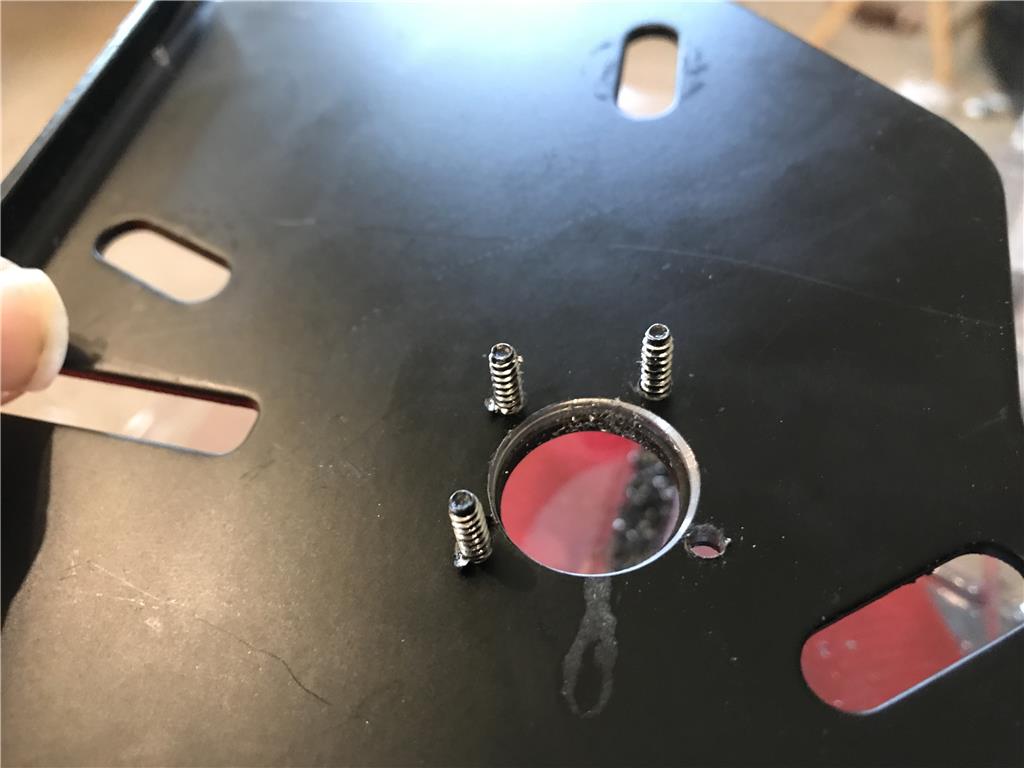
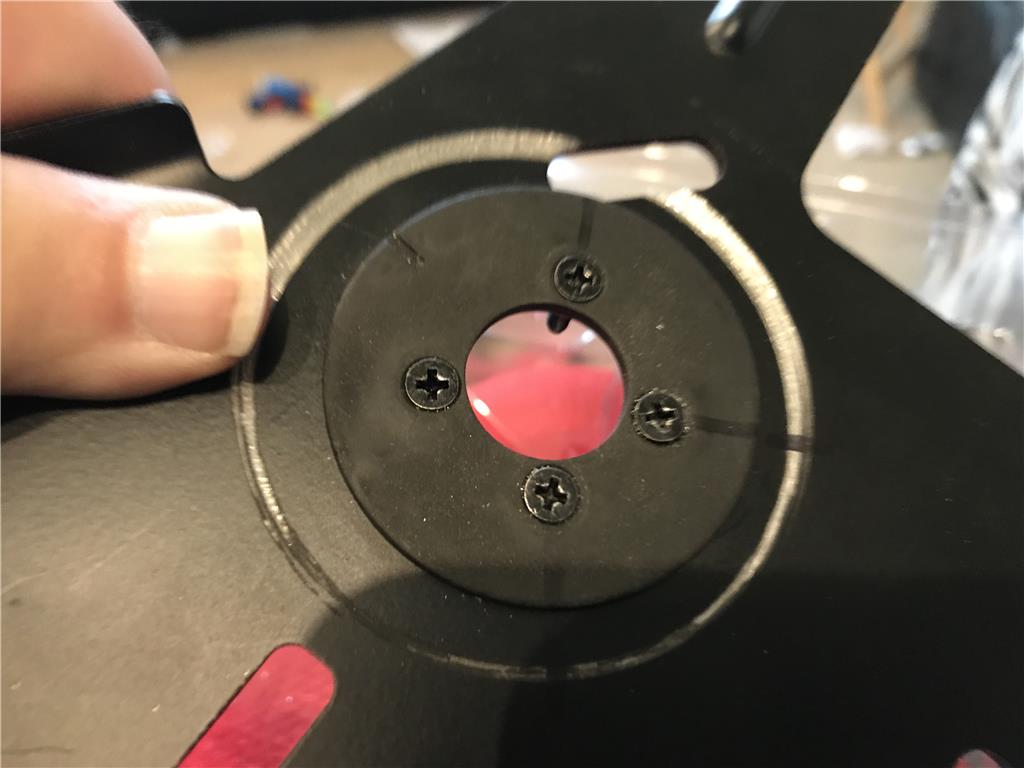
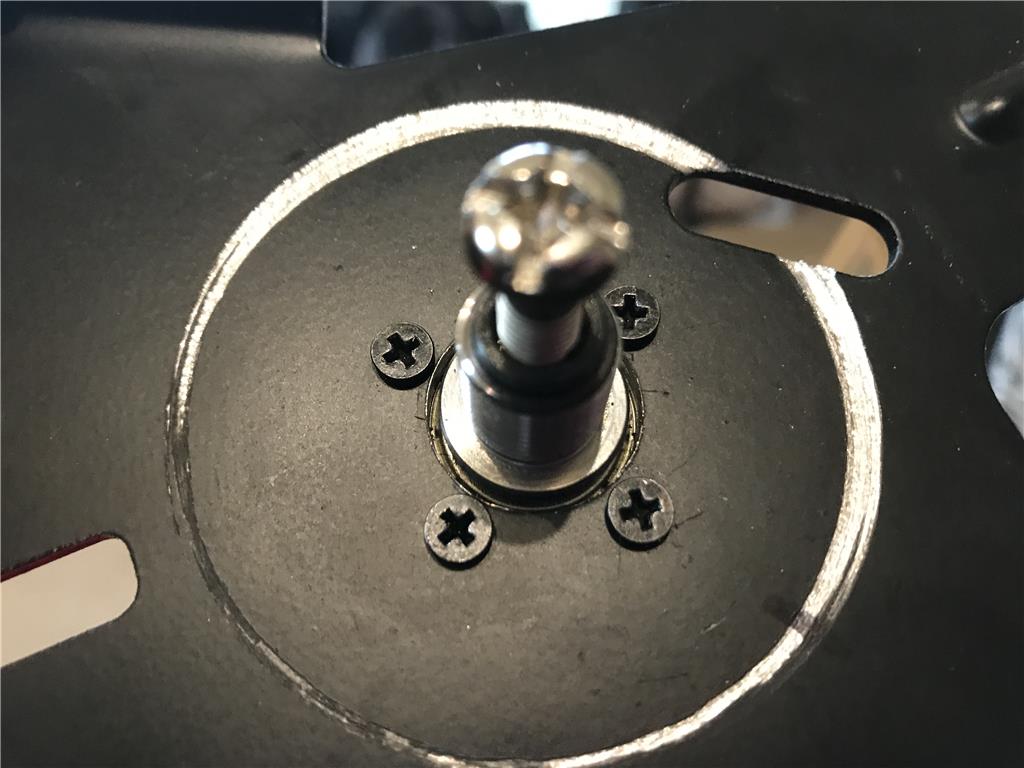
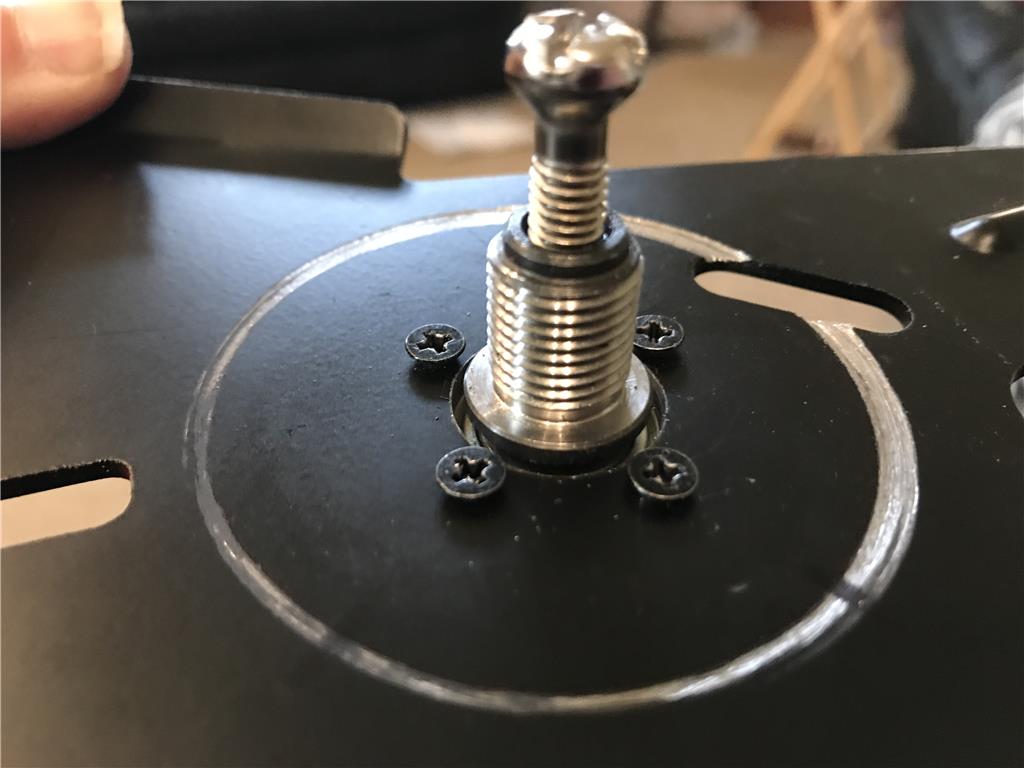
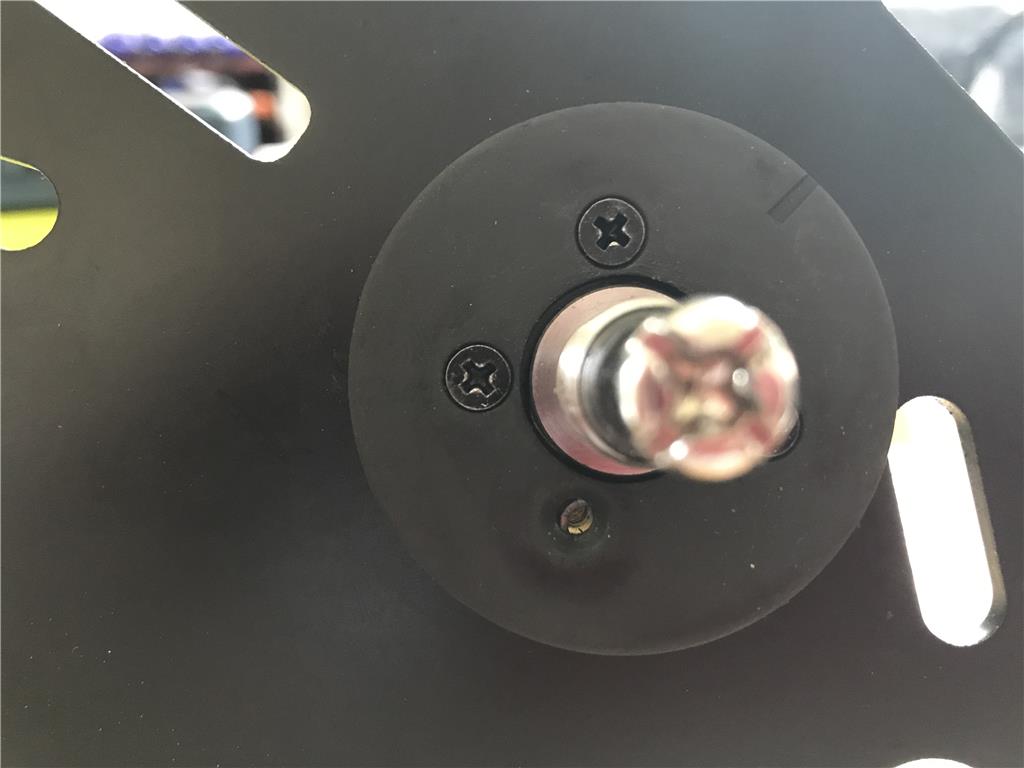
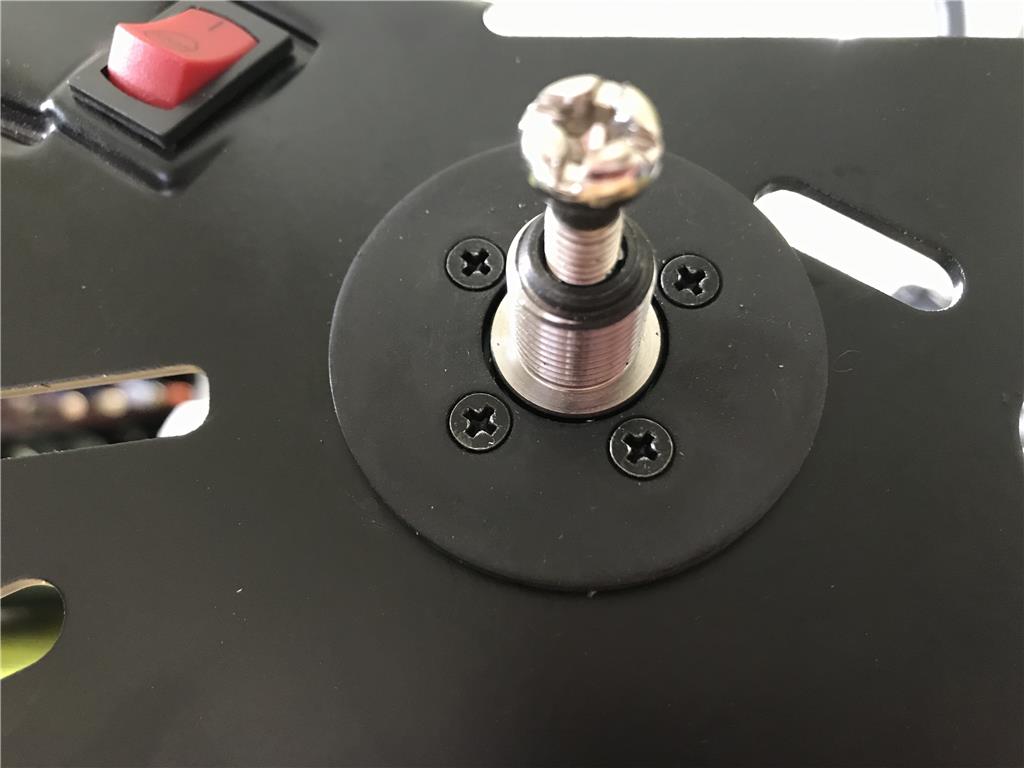
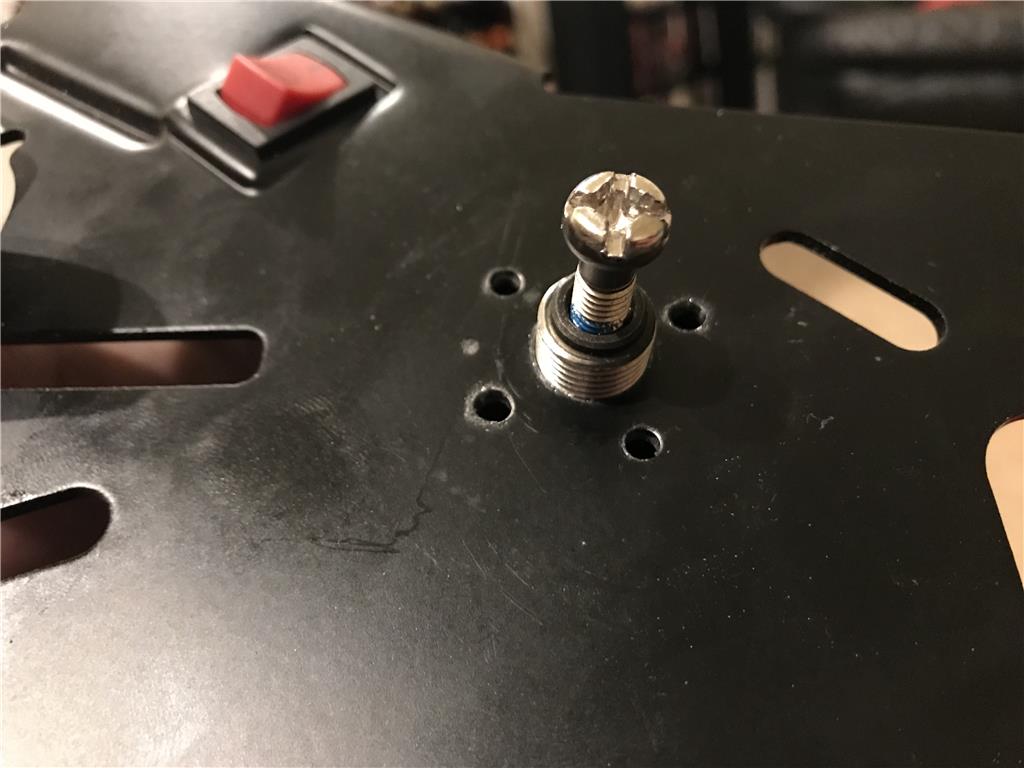
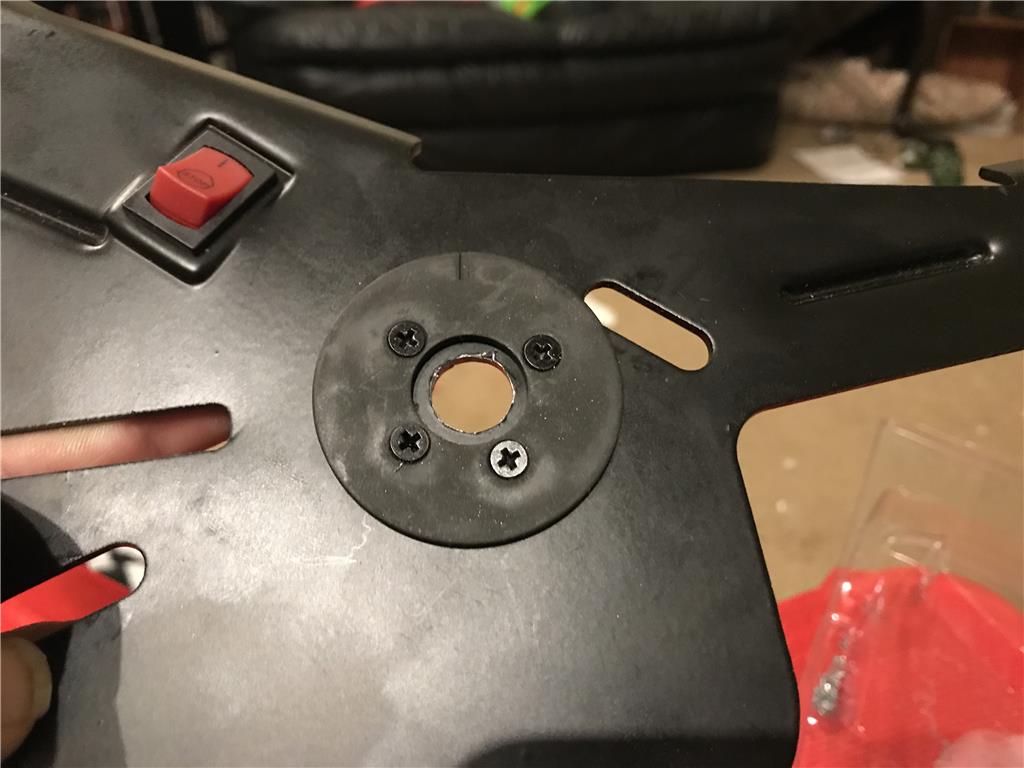
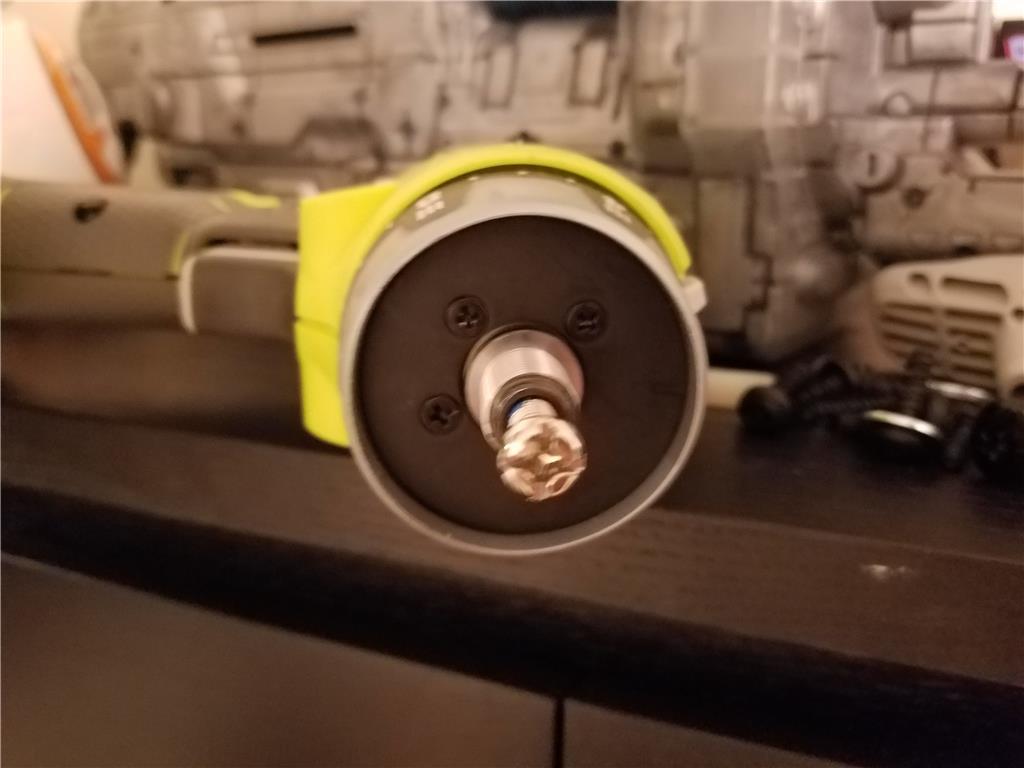
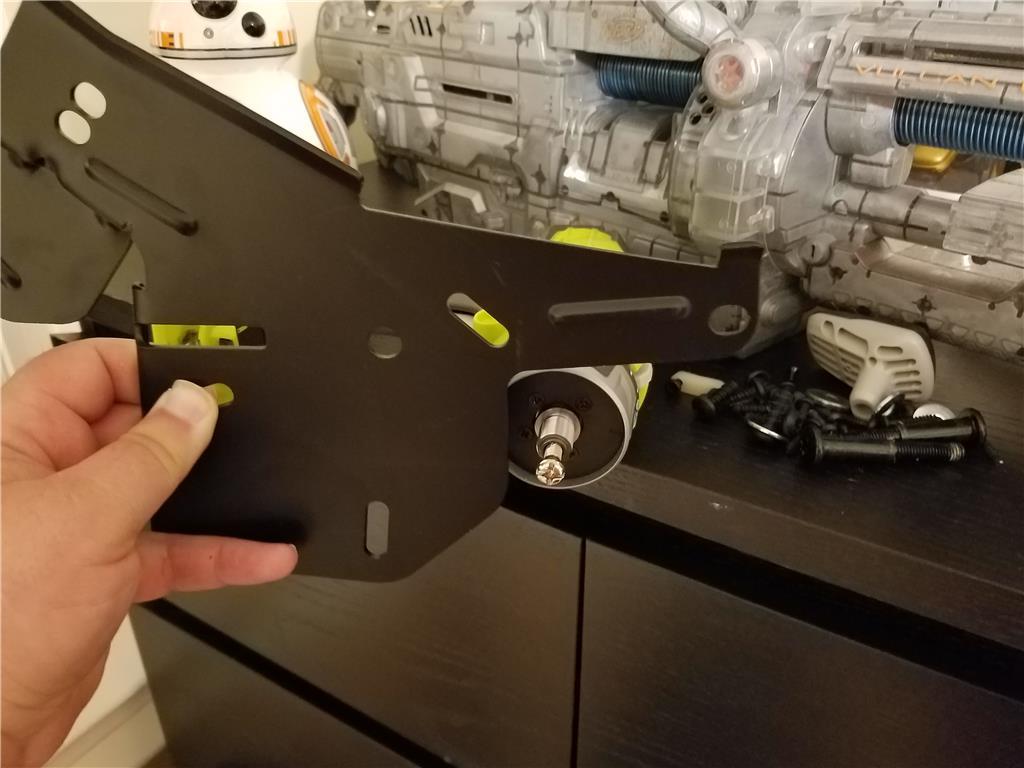
The screws are aligned with the gearbox holes but these screws require a counter sink to screw all the way in. I will use the tip of the stepper /uni-bit to make a counter sink.
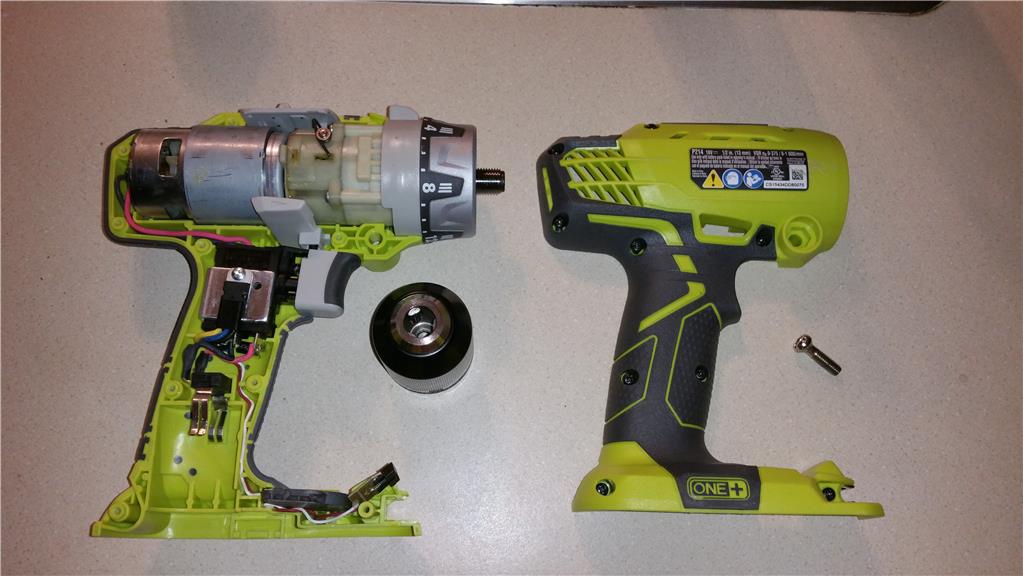
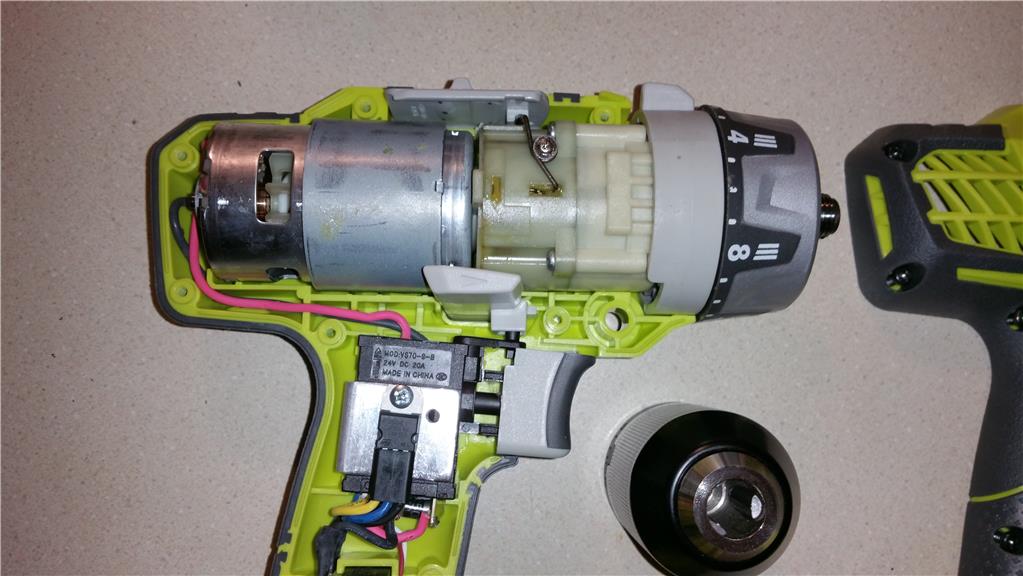
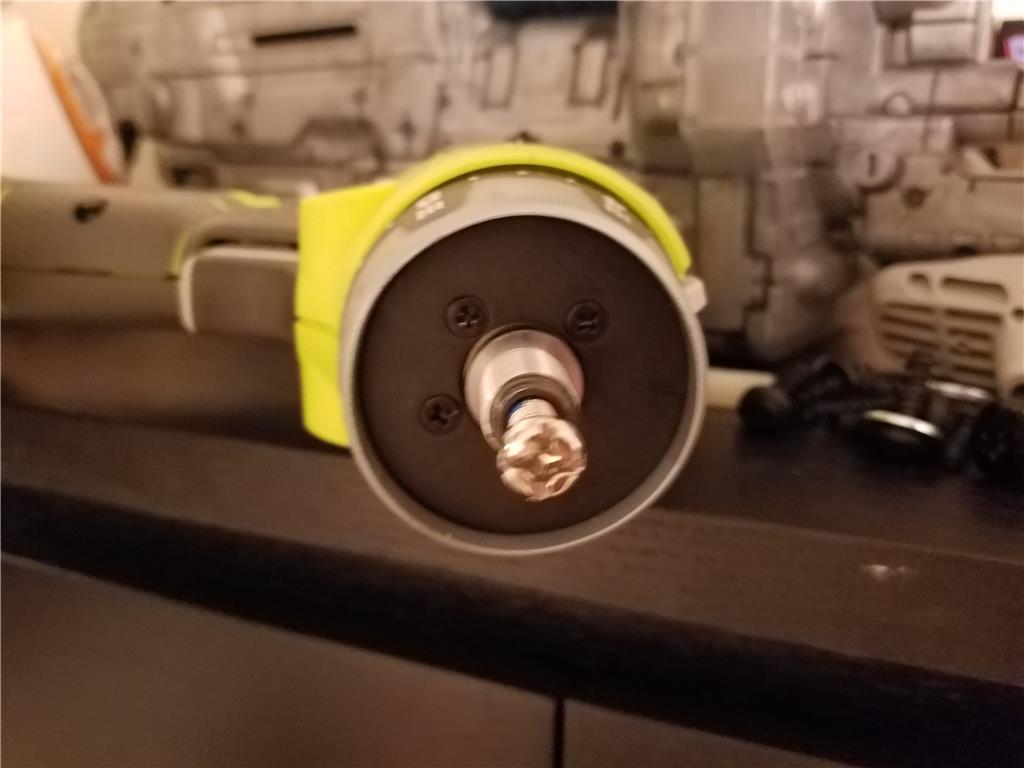
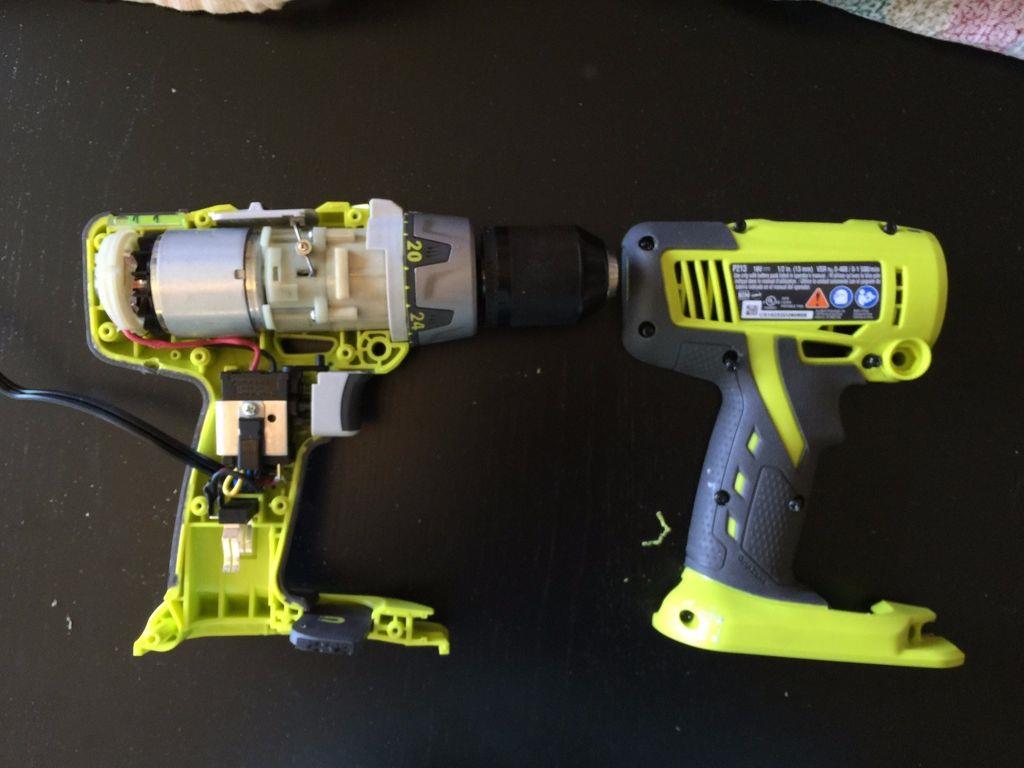
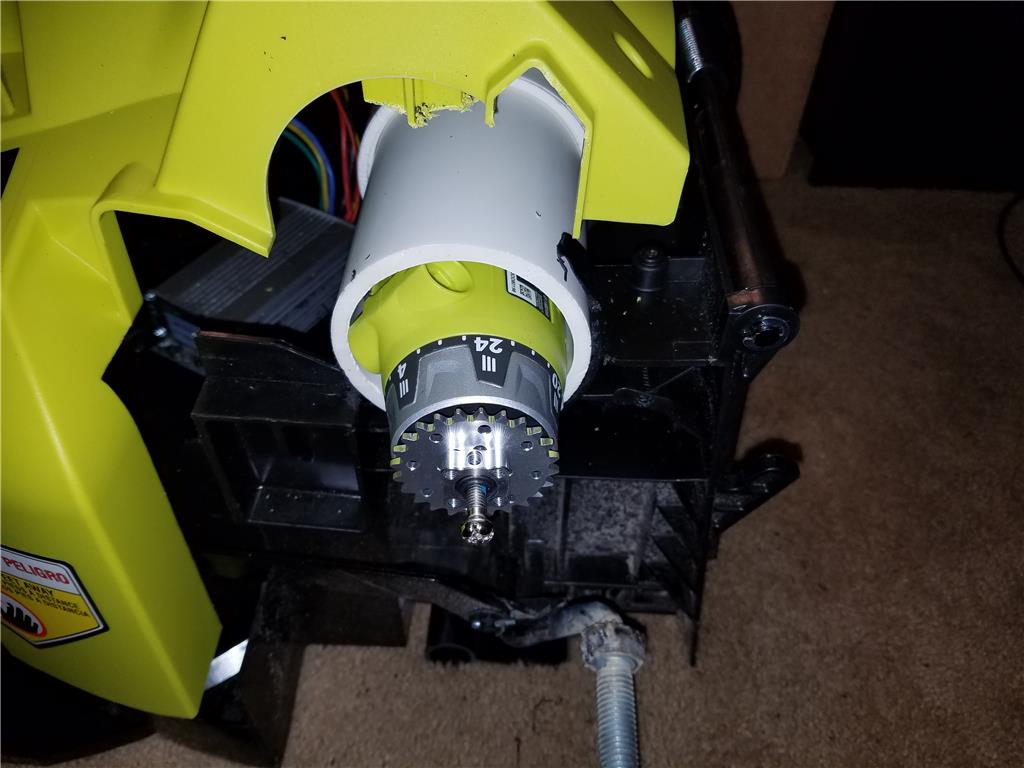
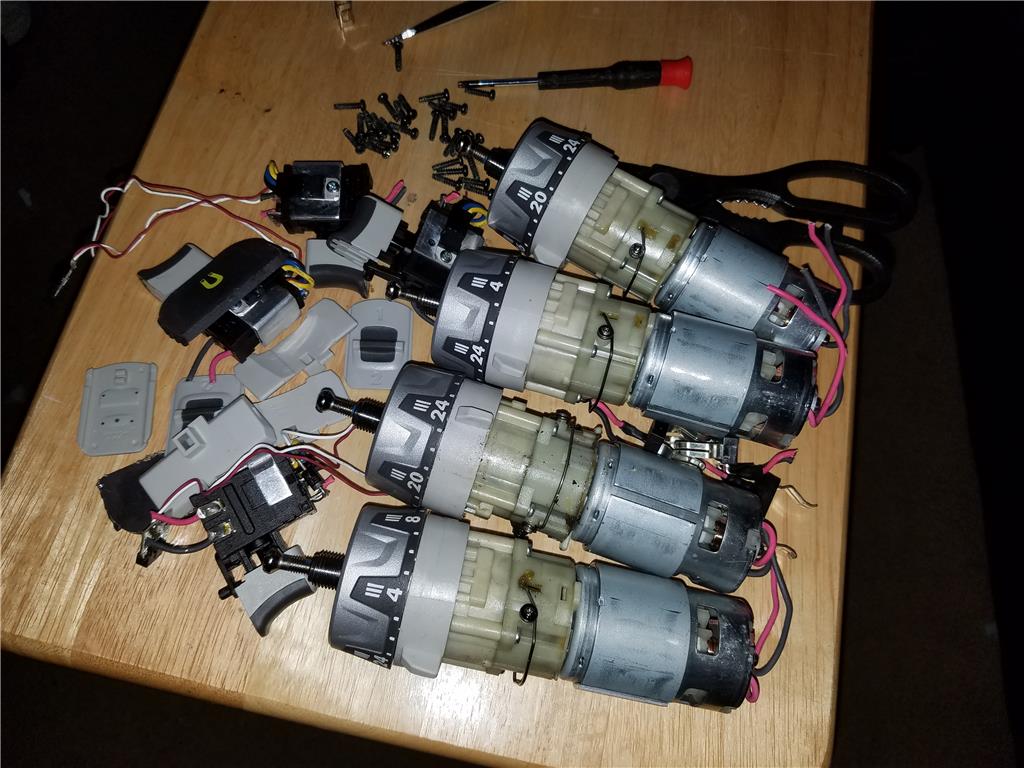
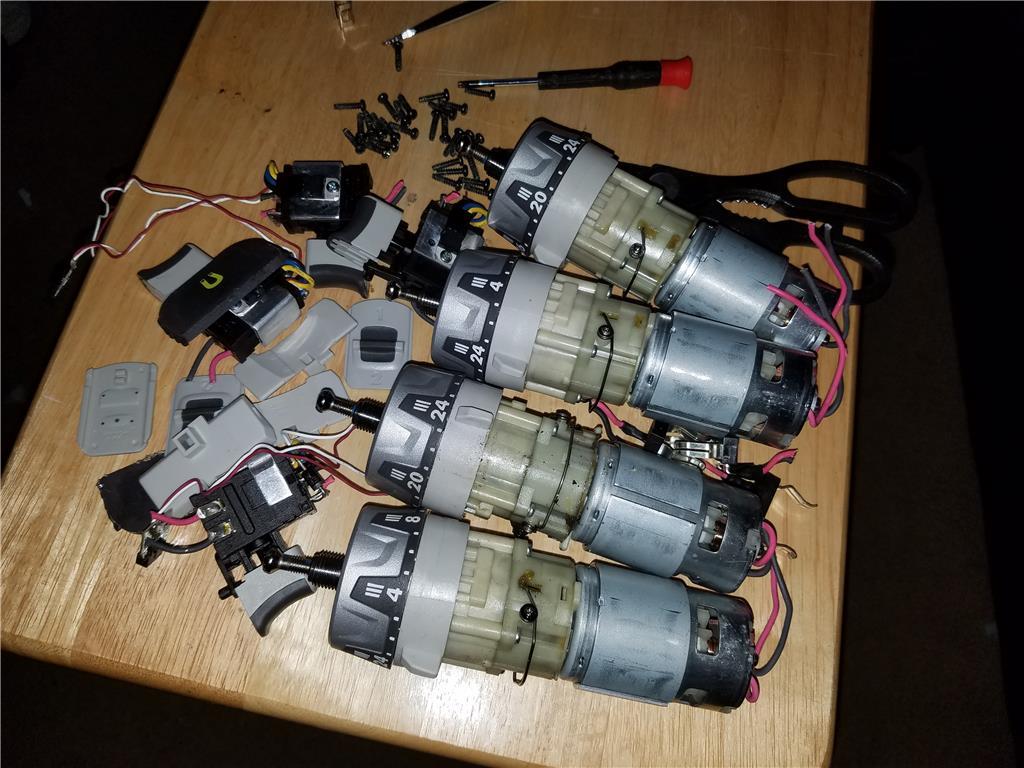
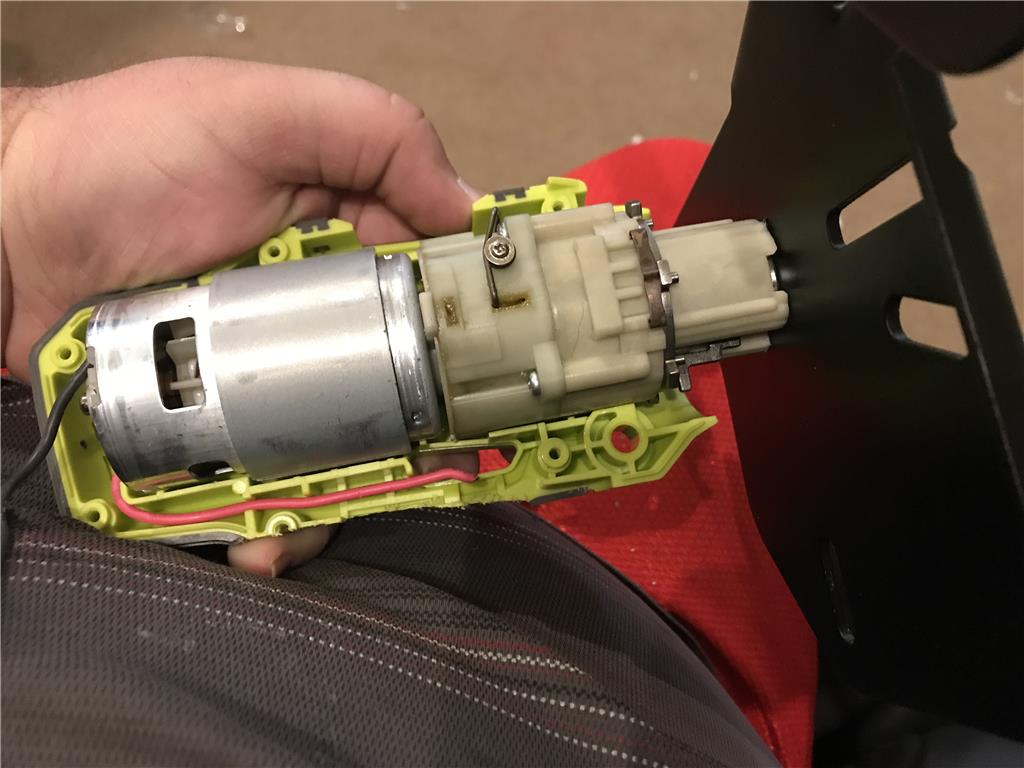
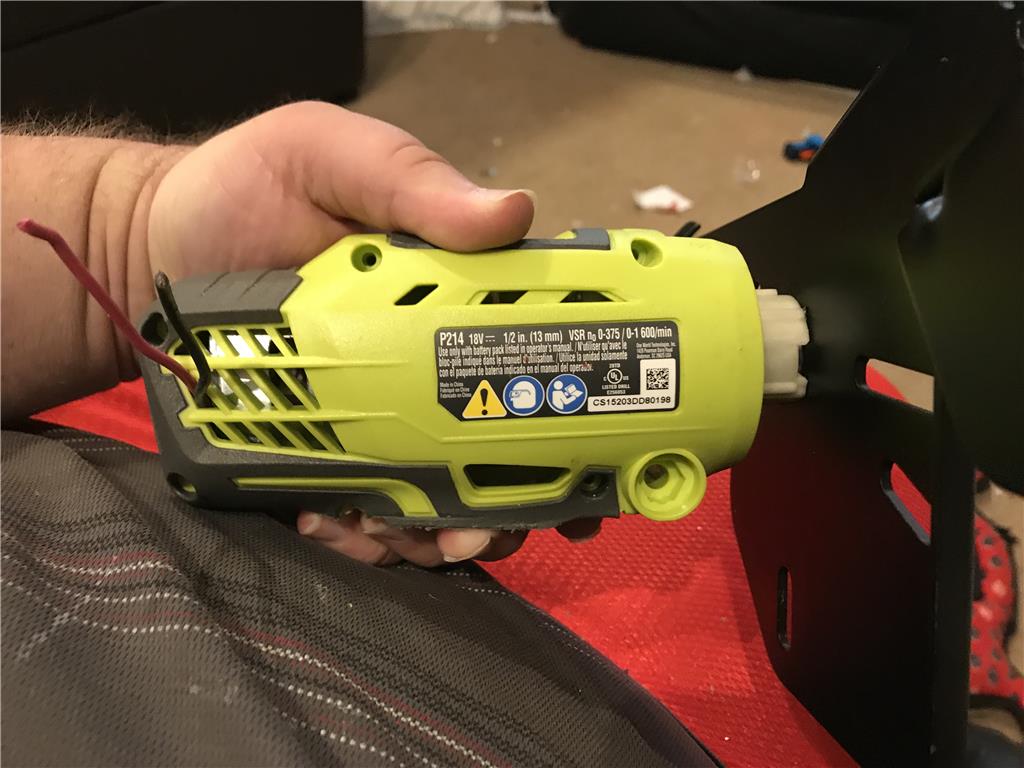
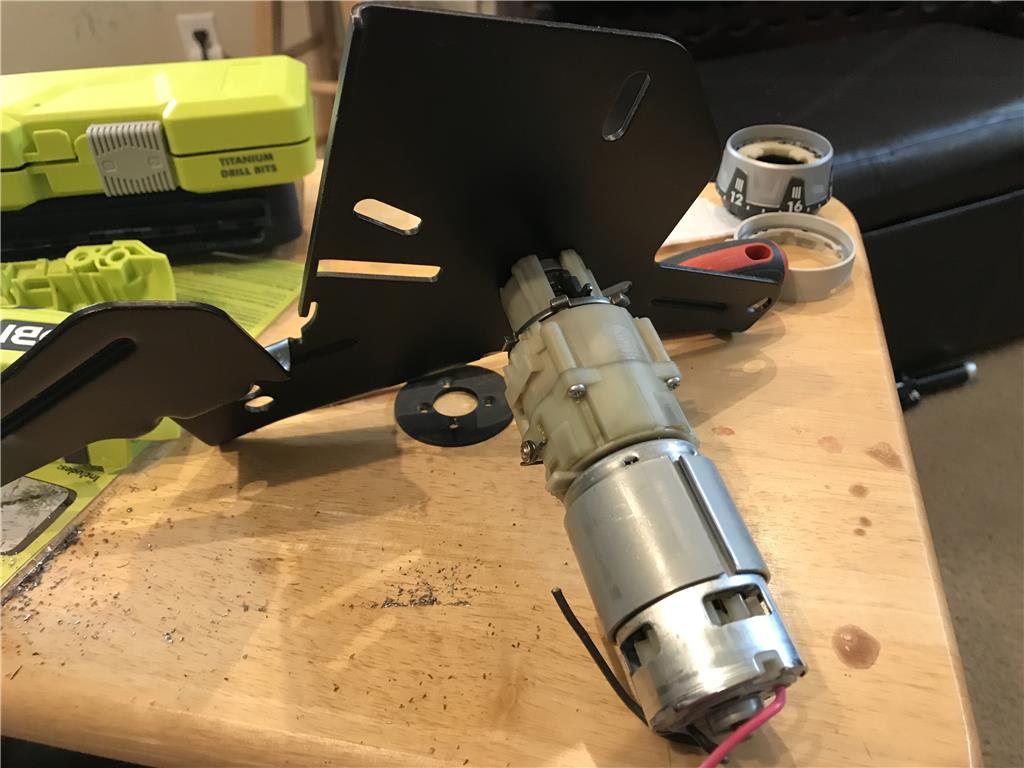
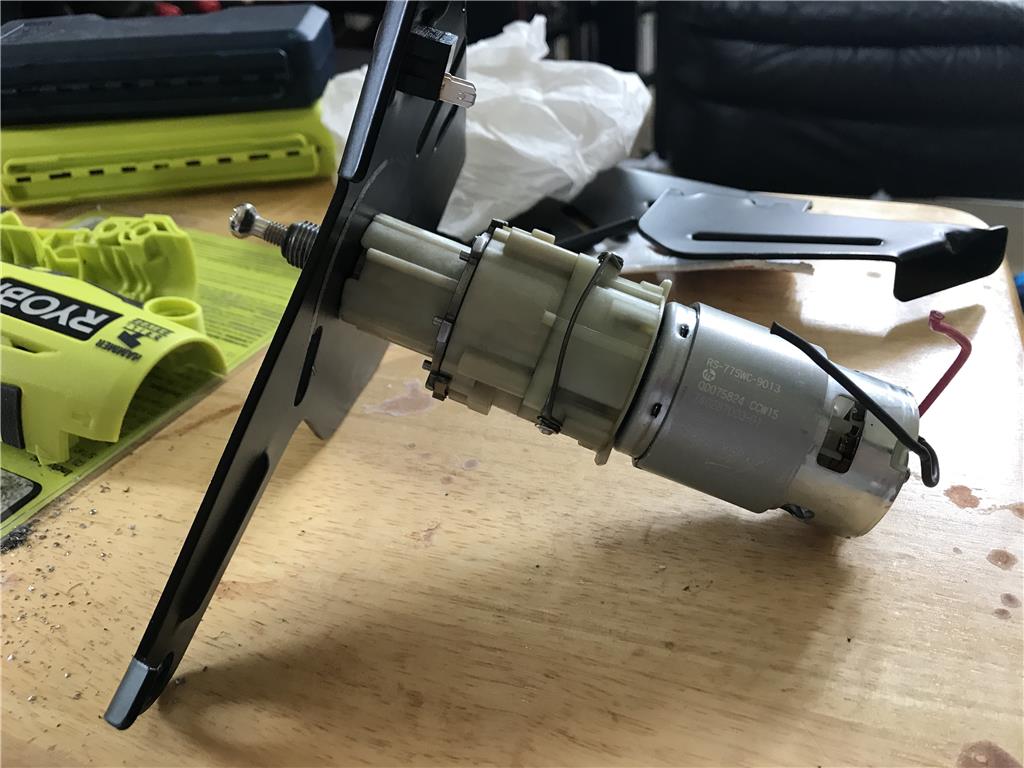
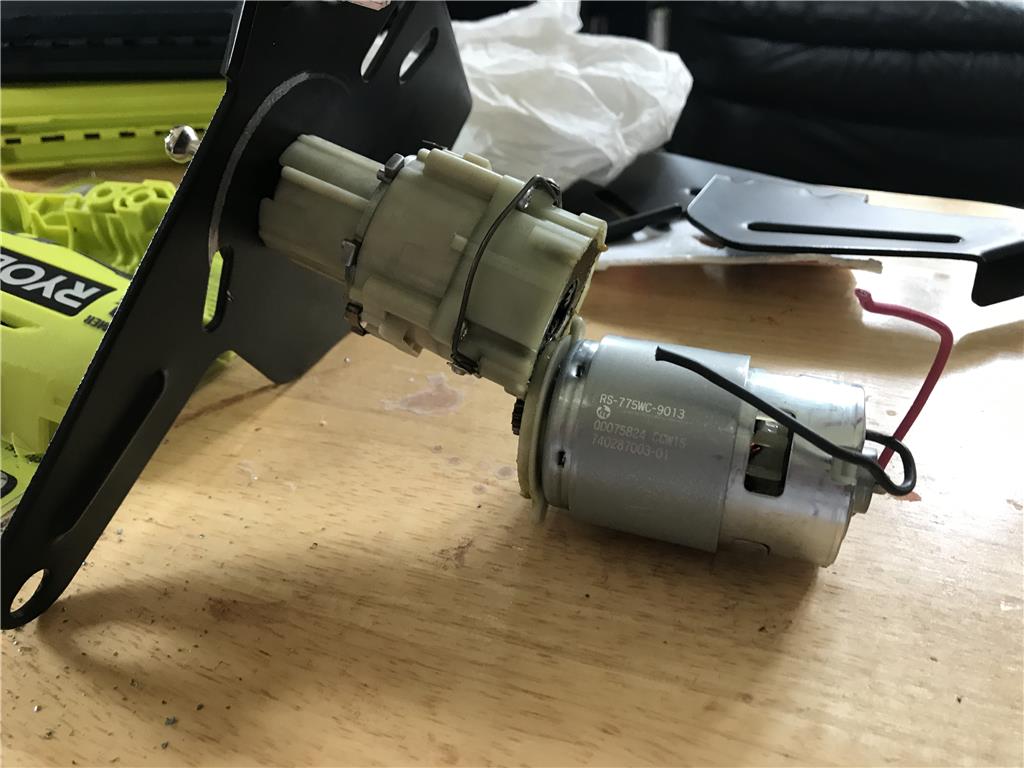
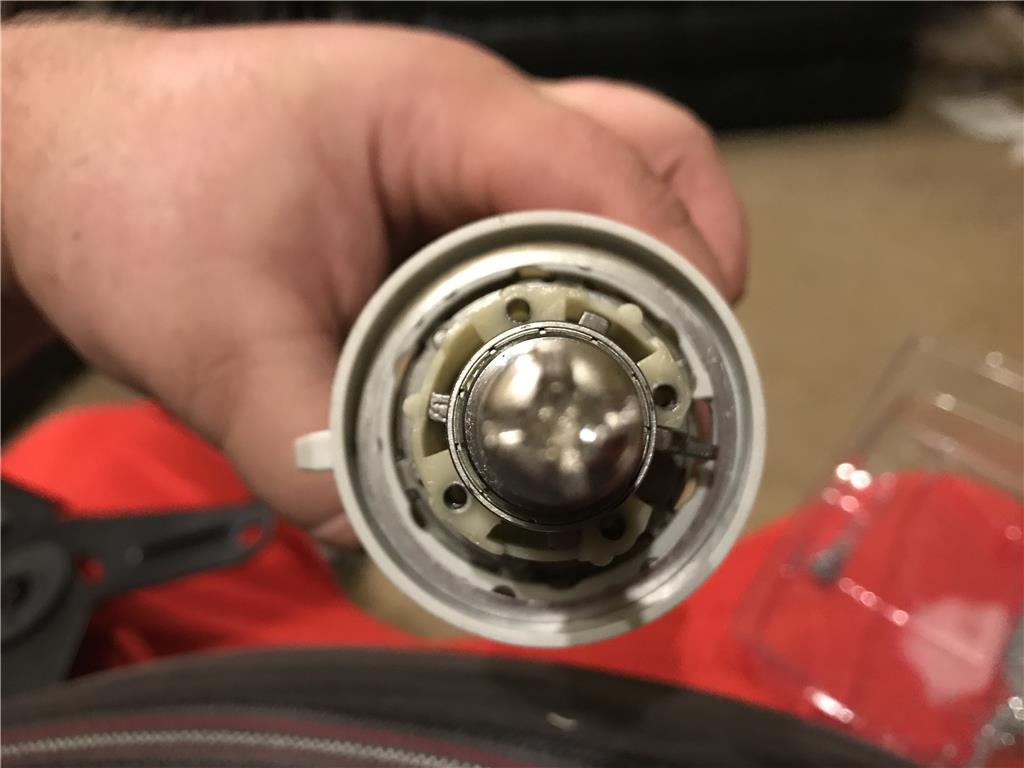
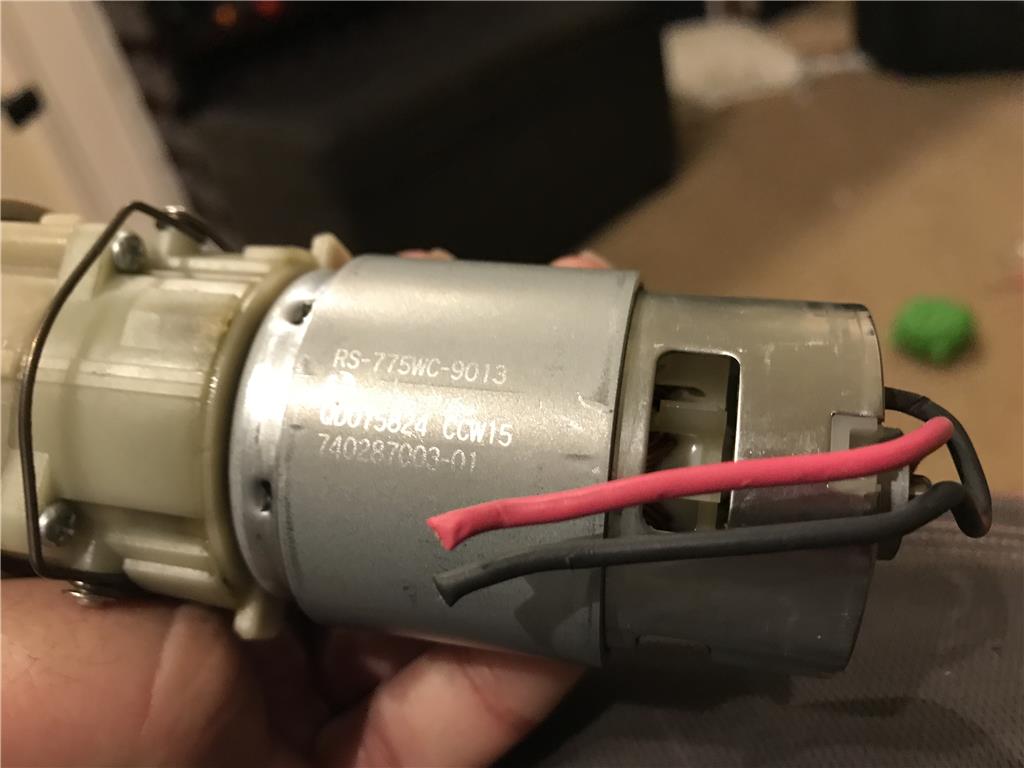
The motor unhooks from the gearbox with a simple 1/8 twist. I believe I will use a portion of the original casing to keep them mated together.
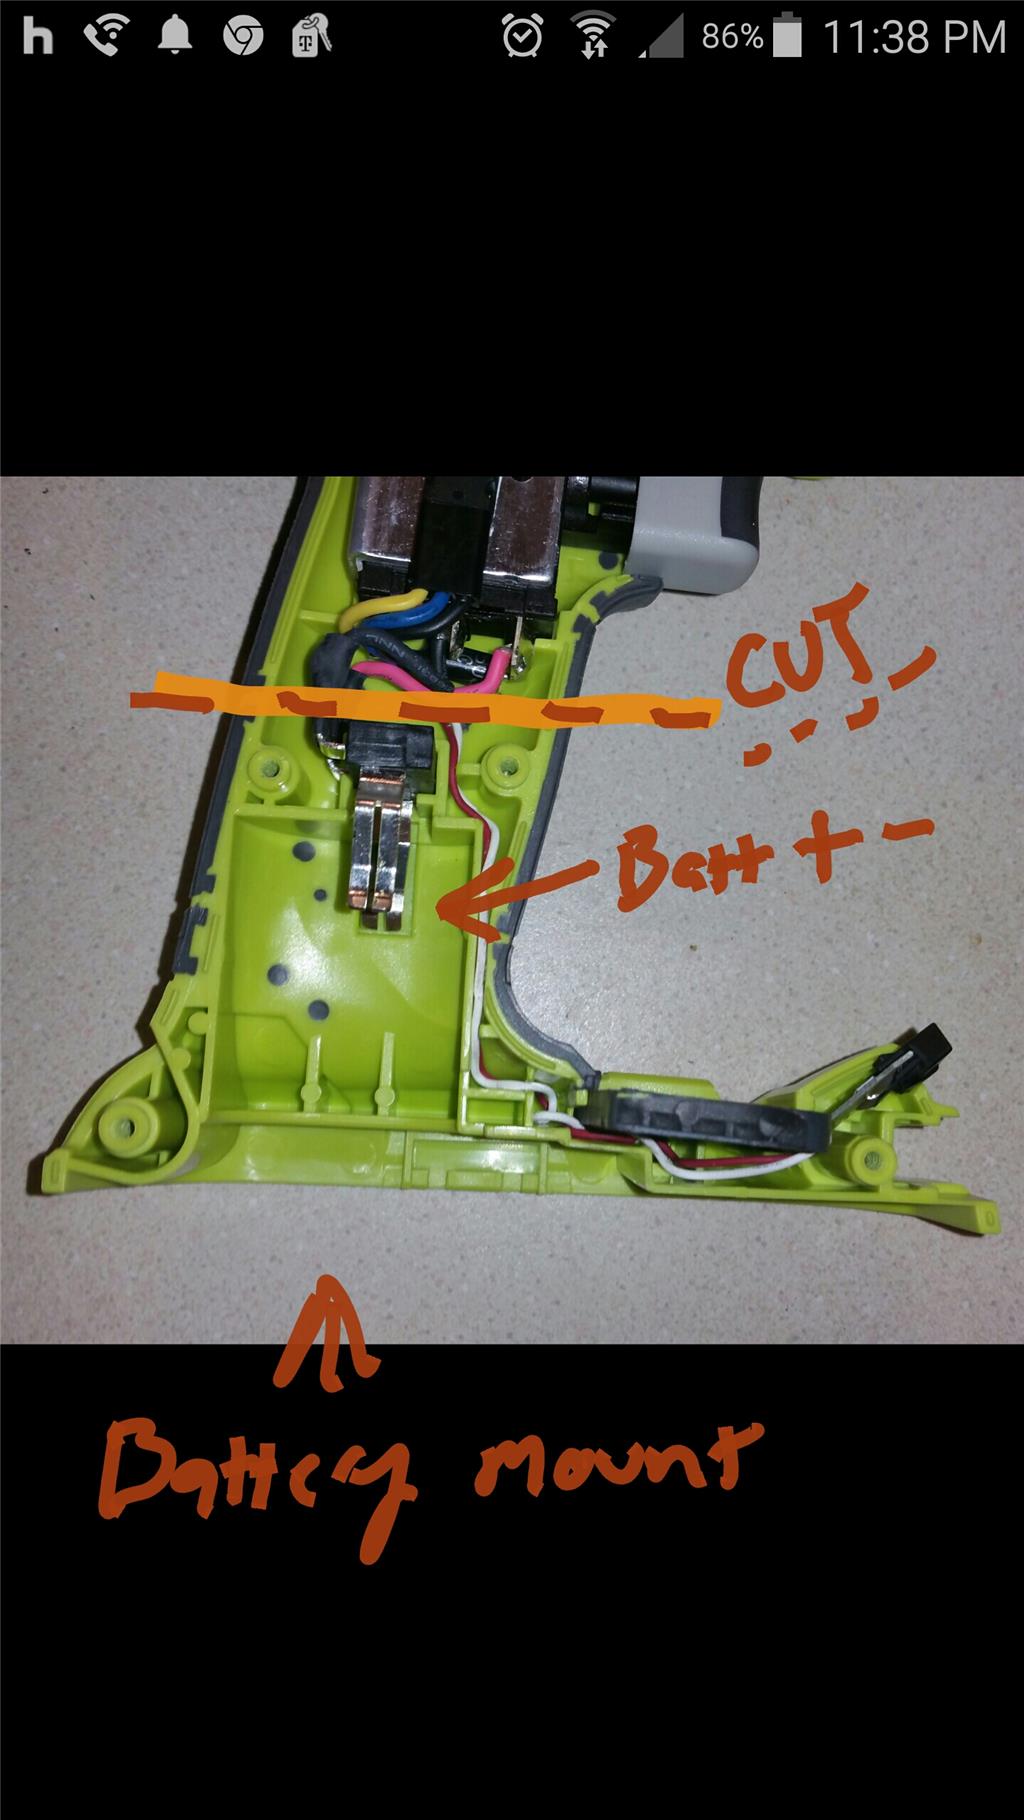
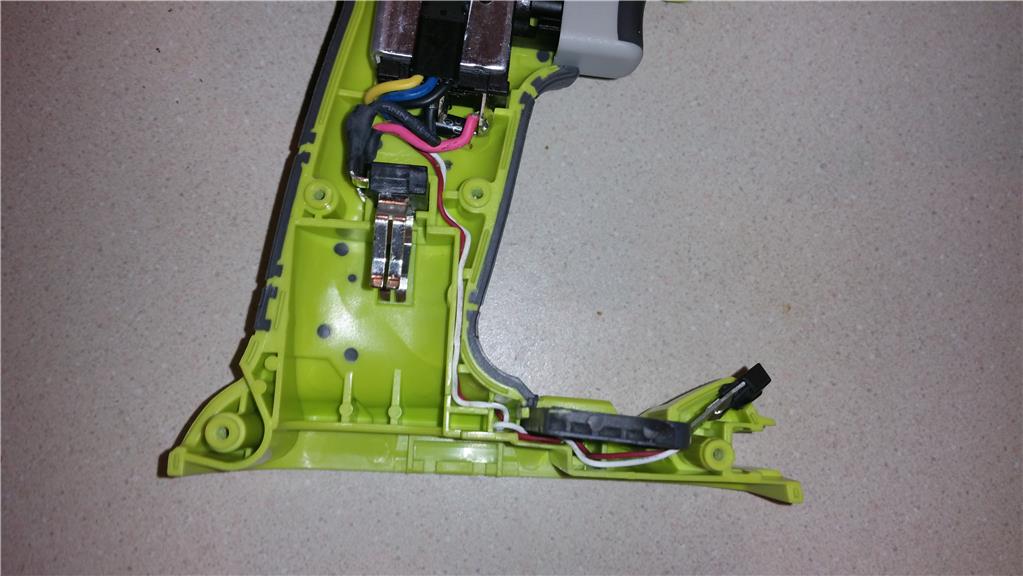
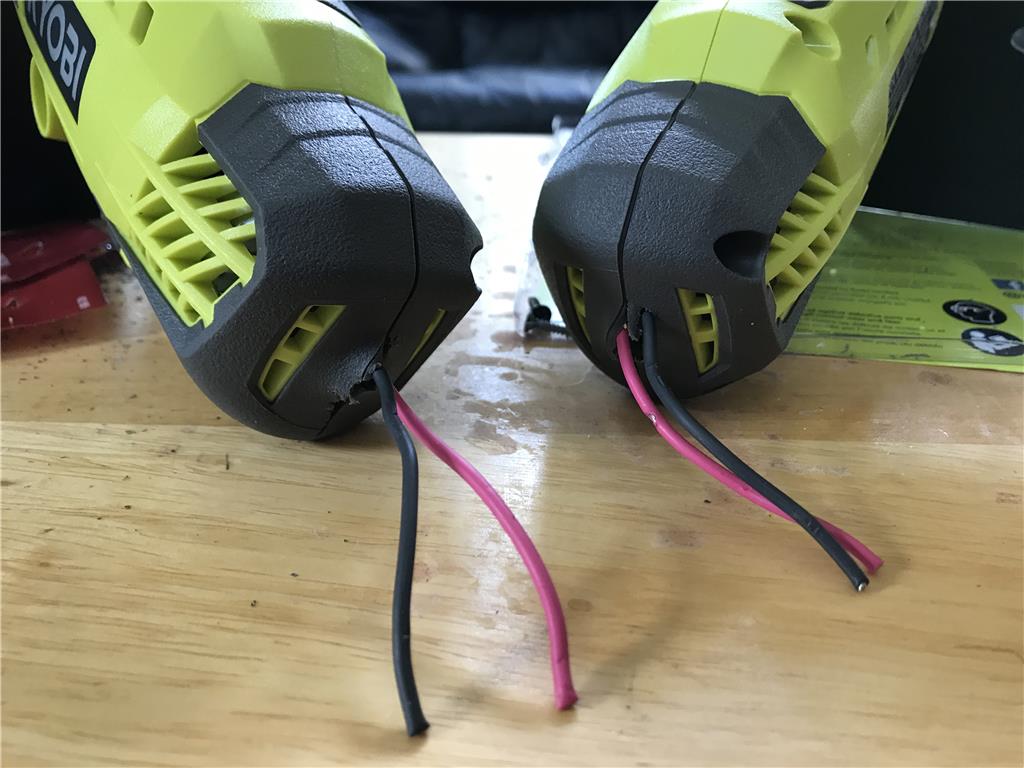
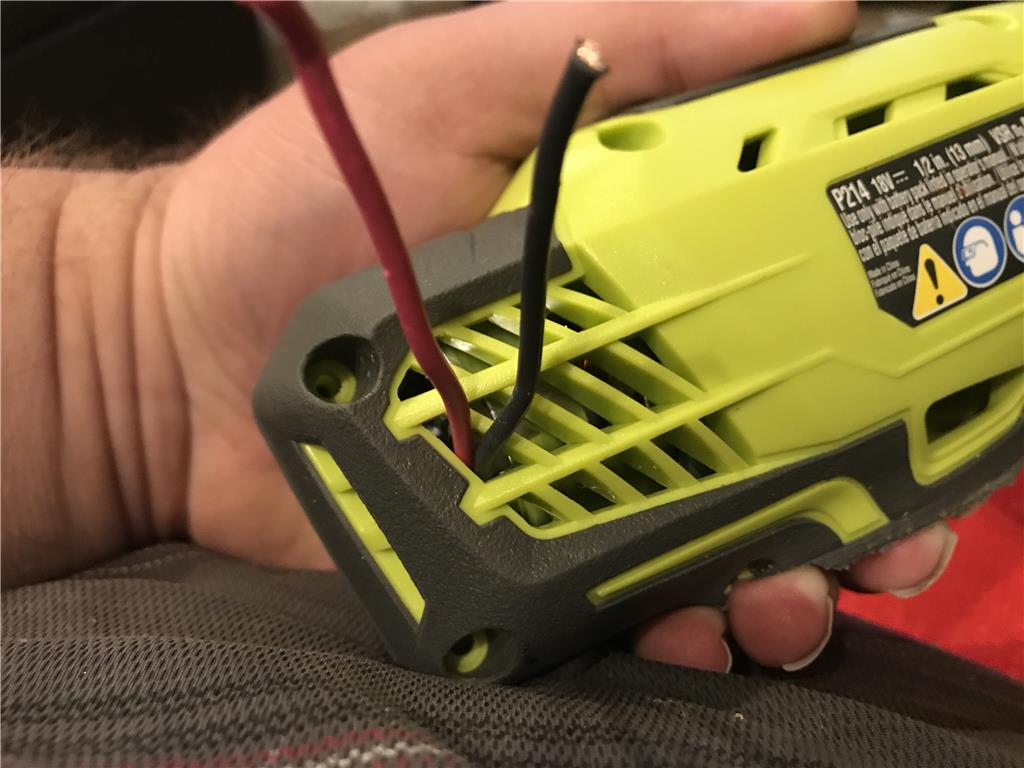
I will add a large hole at the end for the power wires to feed through
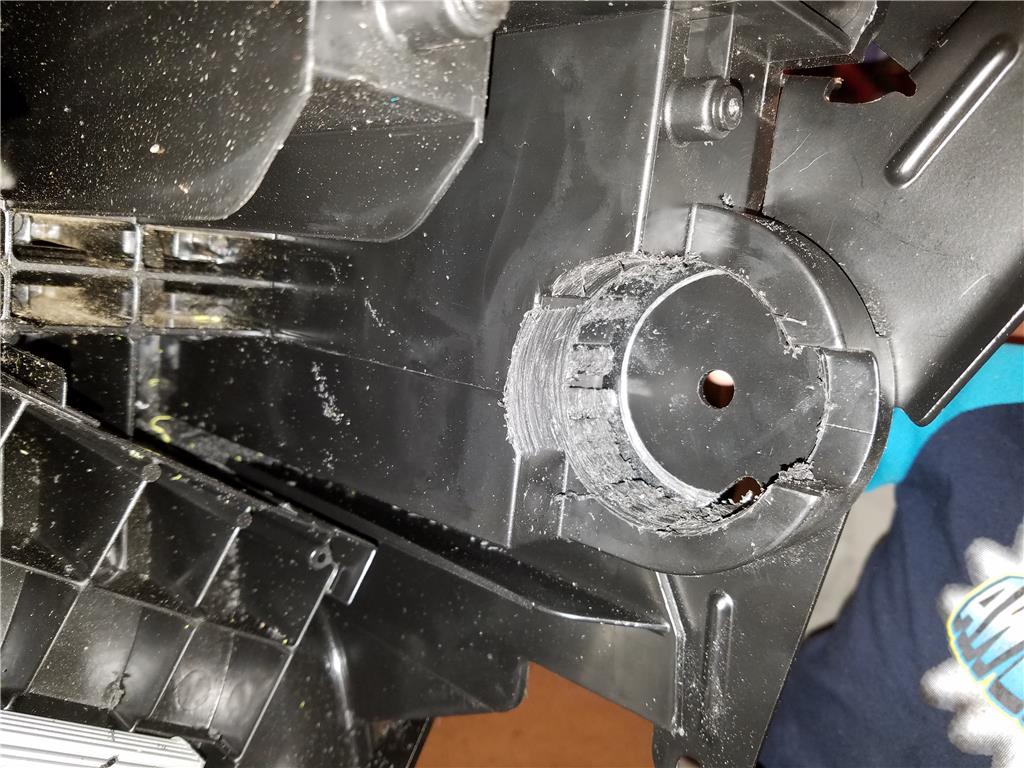
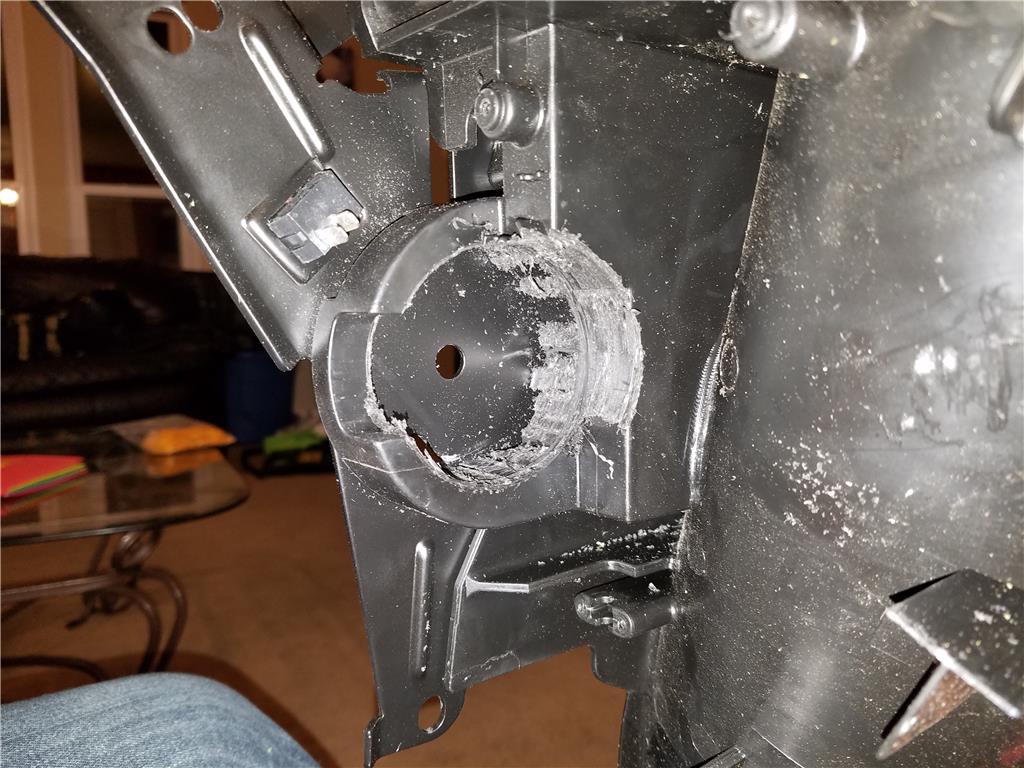
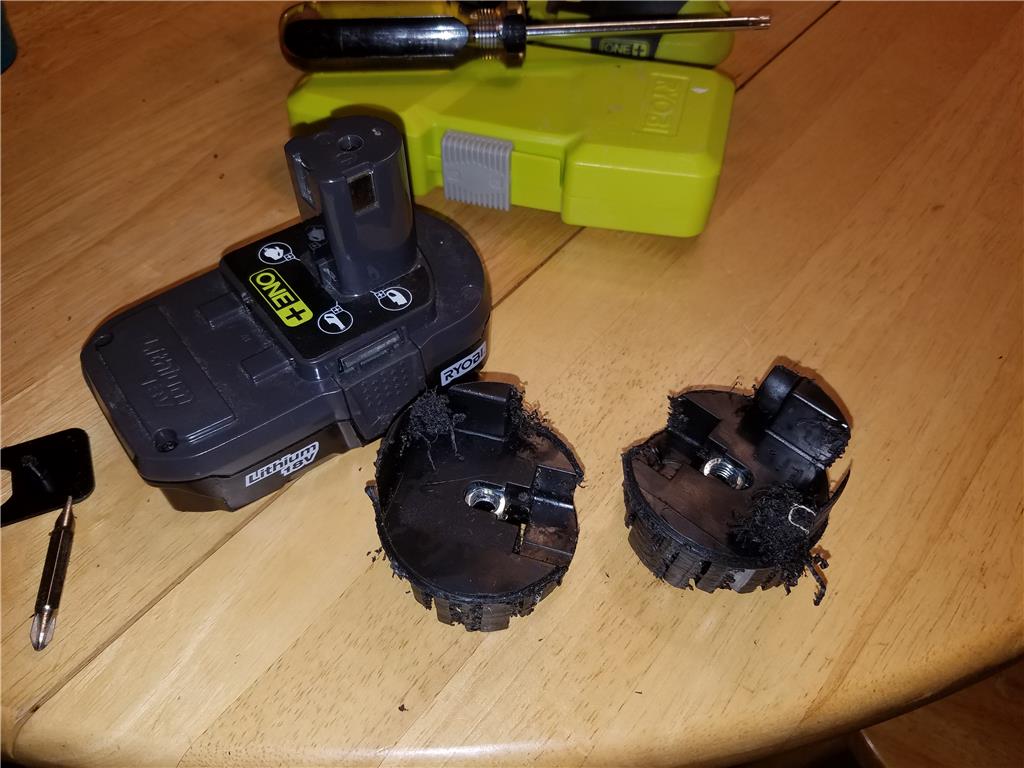
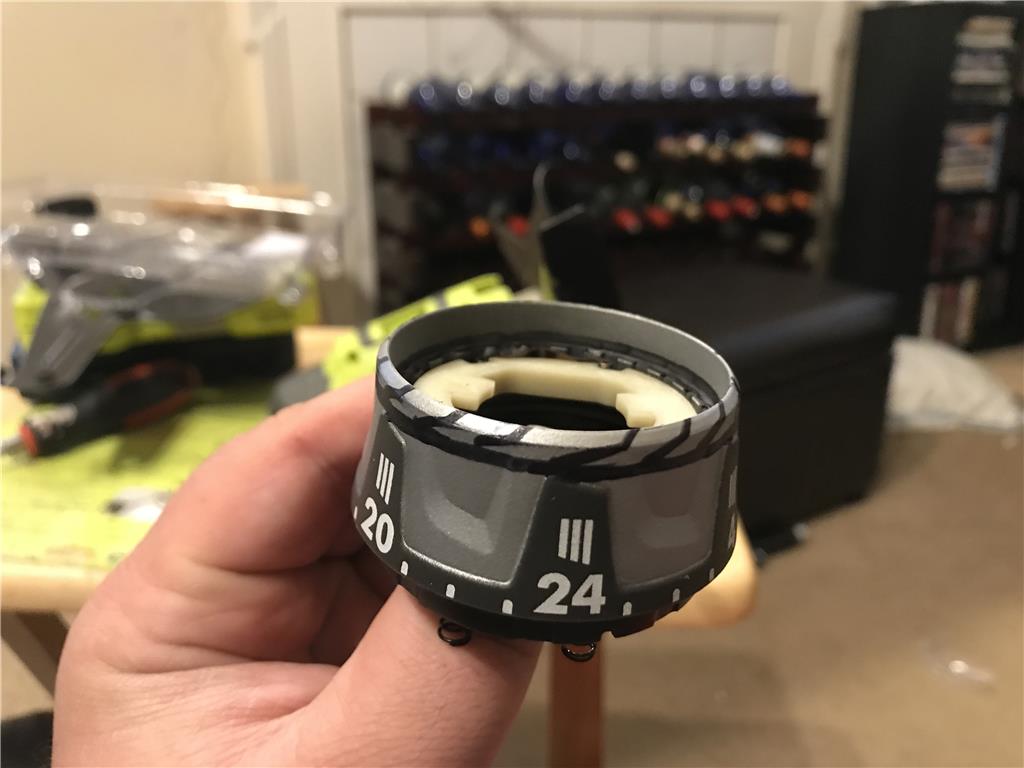
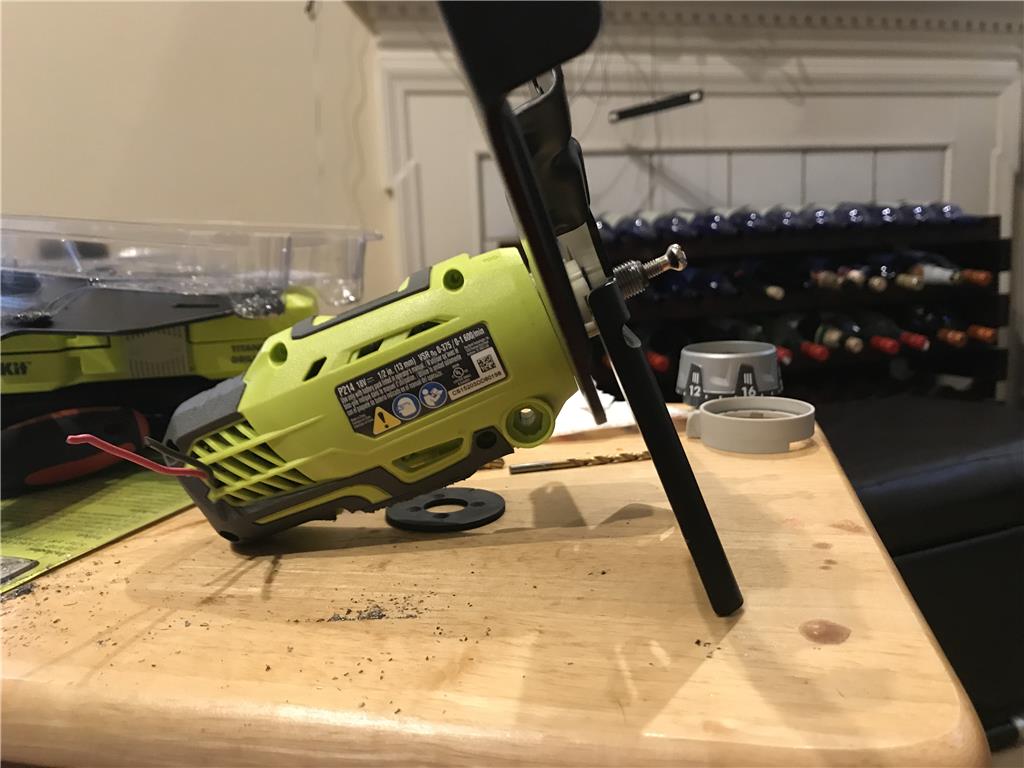
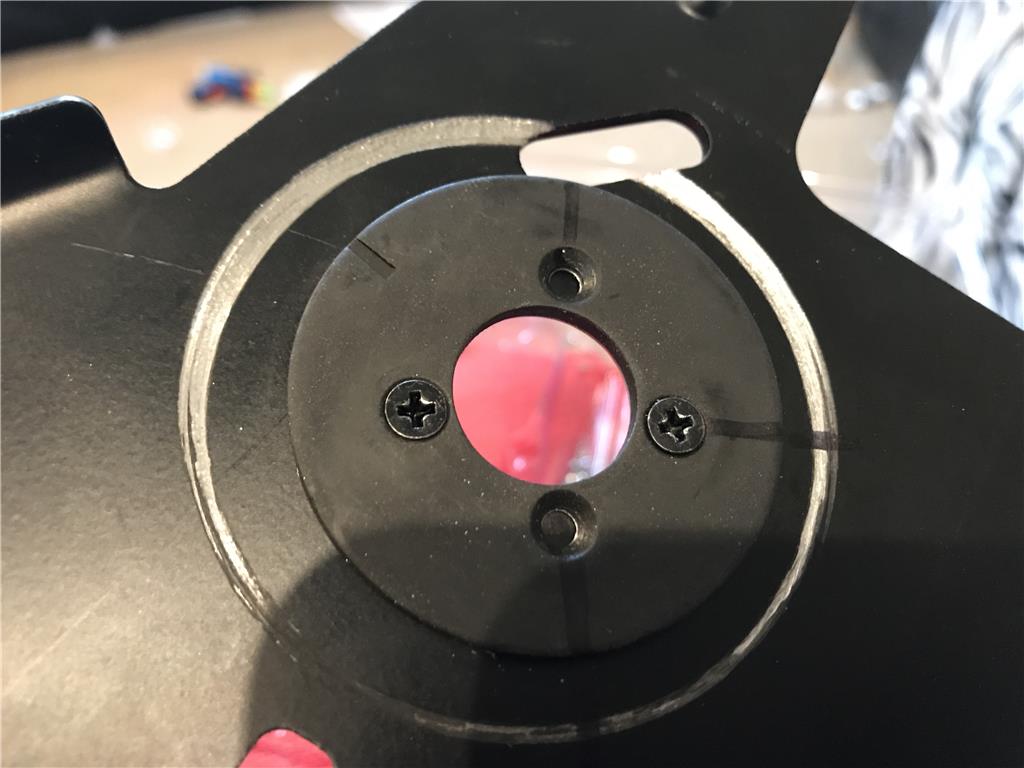
After measuring I found that there is too much plastic lip on the clutch sleeve. I will need to find the dremel and trim down the clutch so that I can fit it behind the metal plate and still be able to screw it all the way down to the face of the gearbox.
On a side note I am going to go find those nail clippers! Those are scary.
Those nails will work well for stripping wire.....
Project is going well. Looking forward to more.
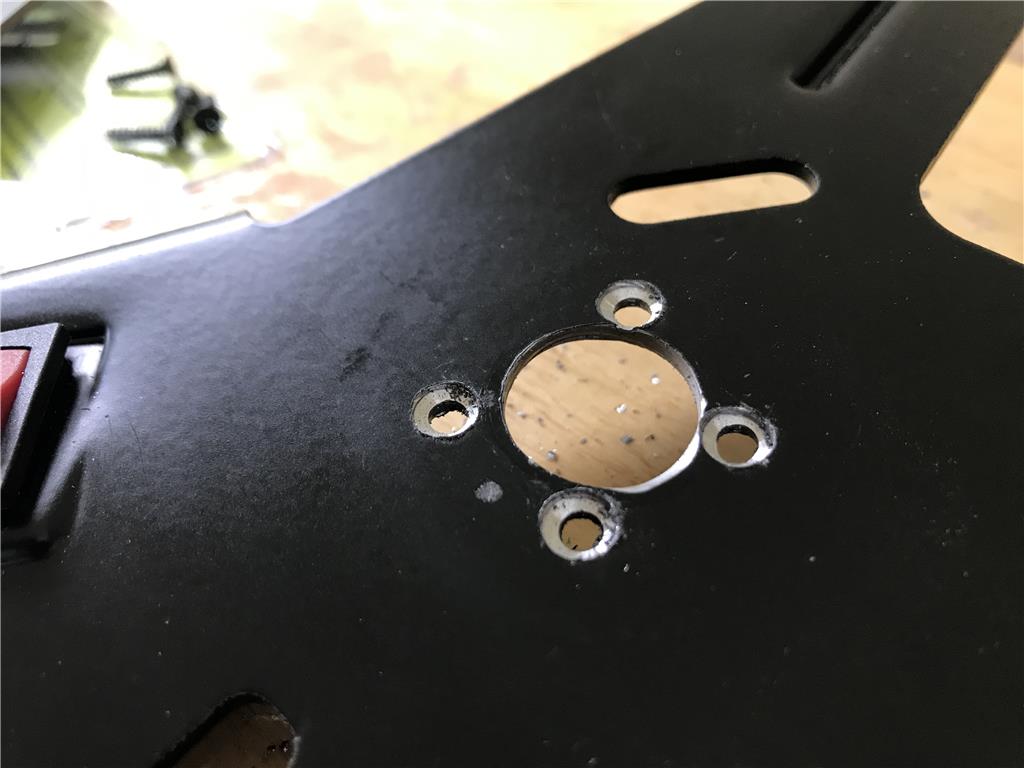
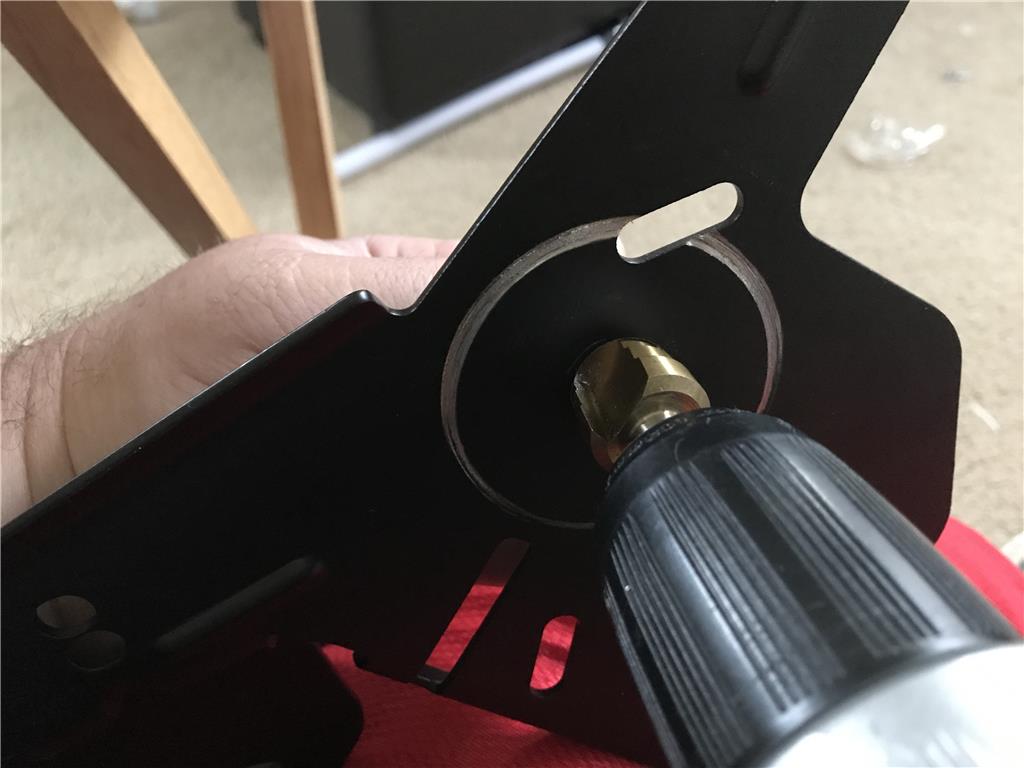
Ok so I used a larger bit and slowly machined out the holes to countersink the screws.
They sink in well now
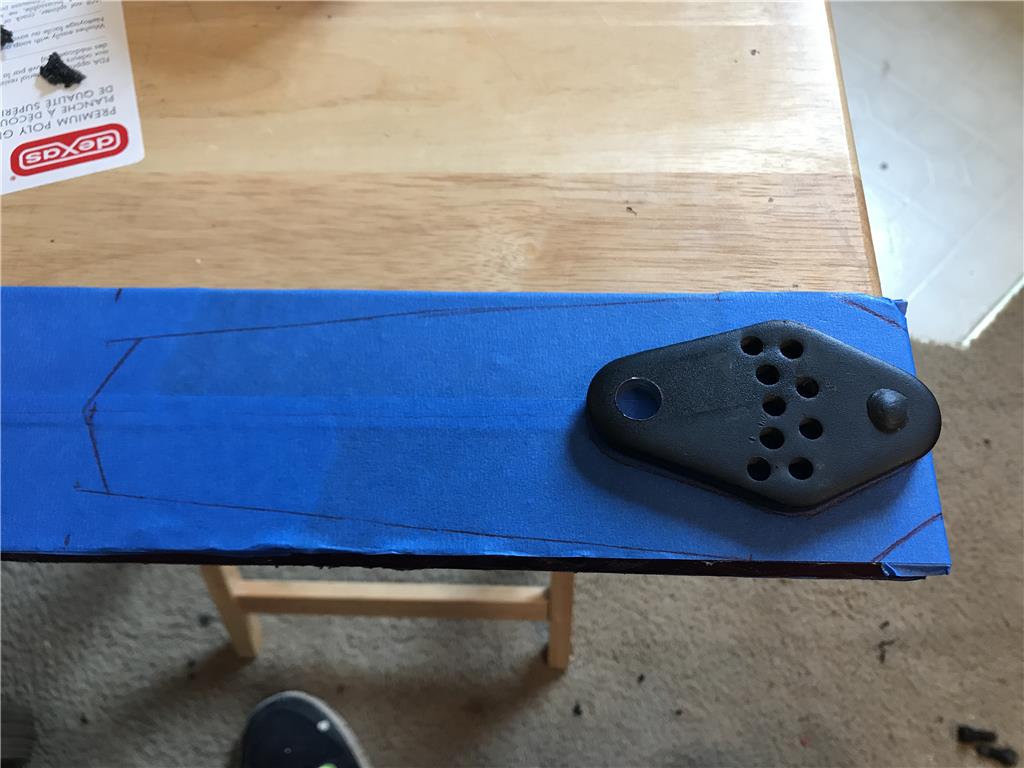
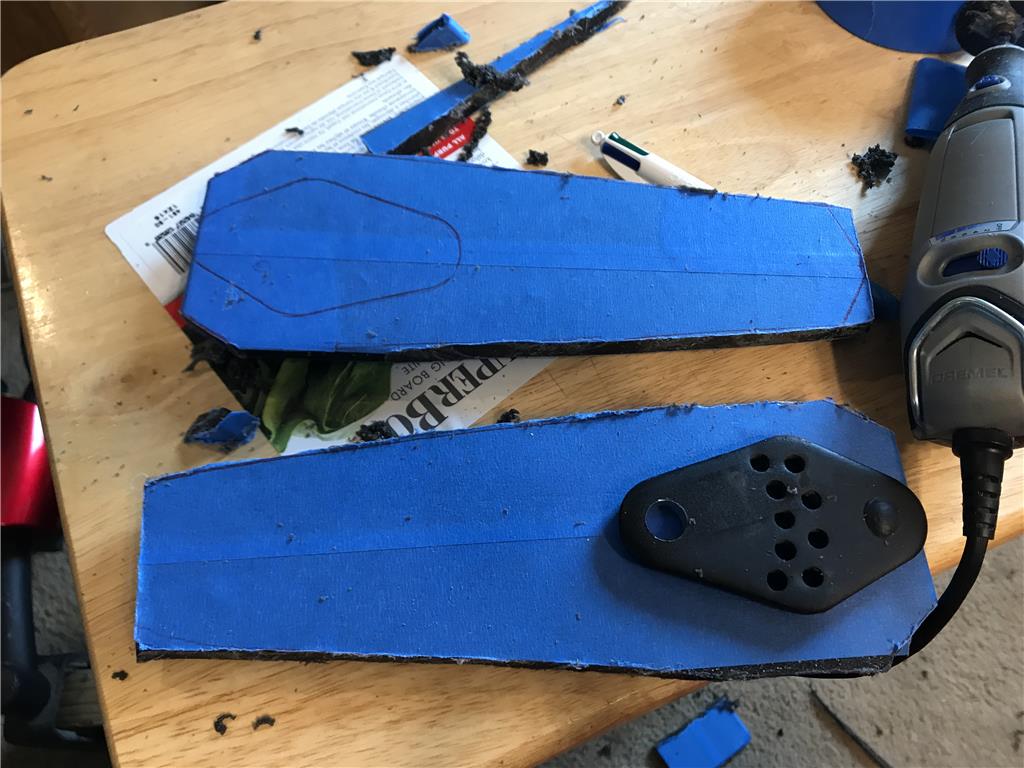
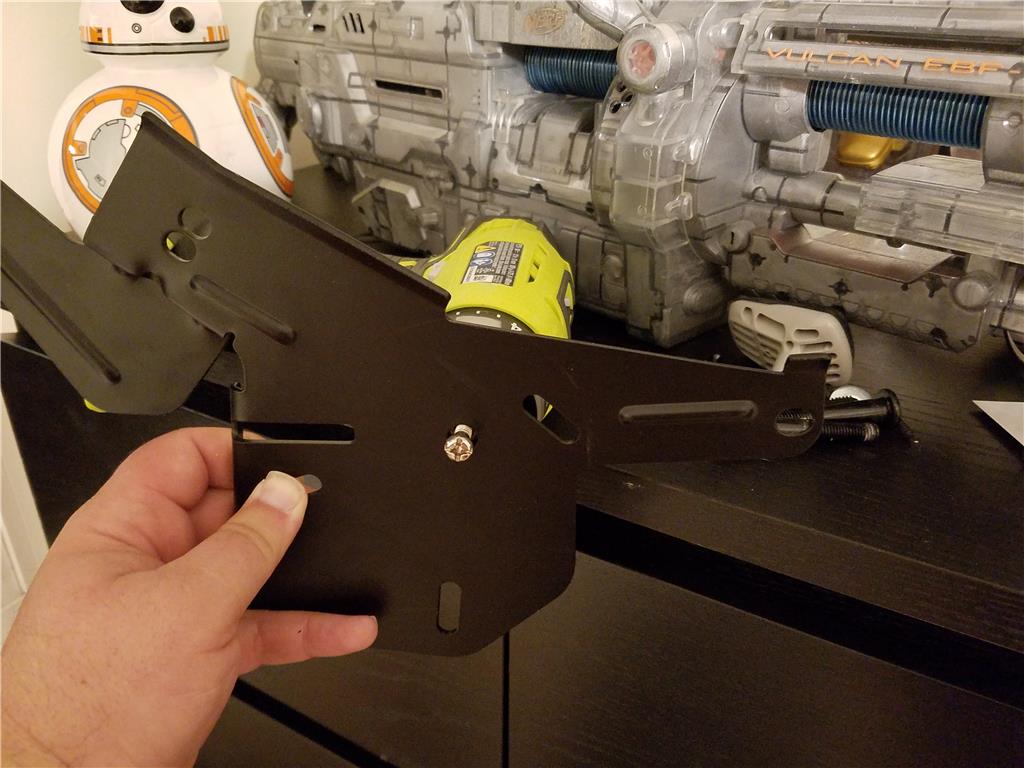
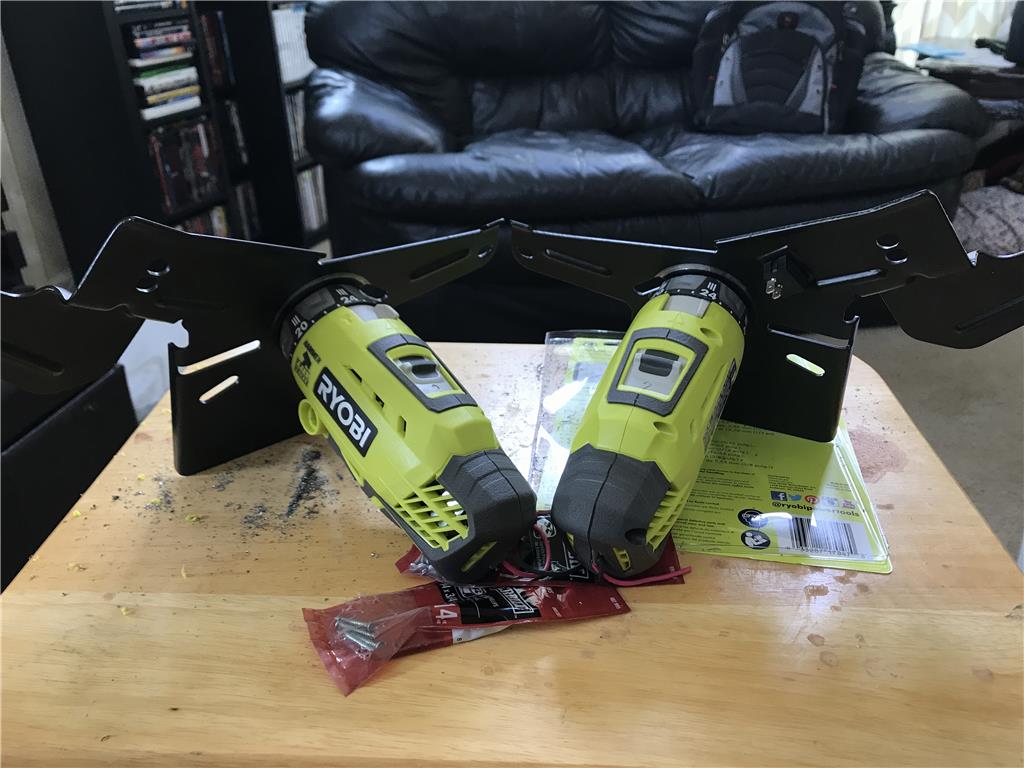
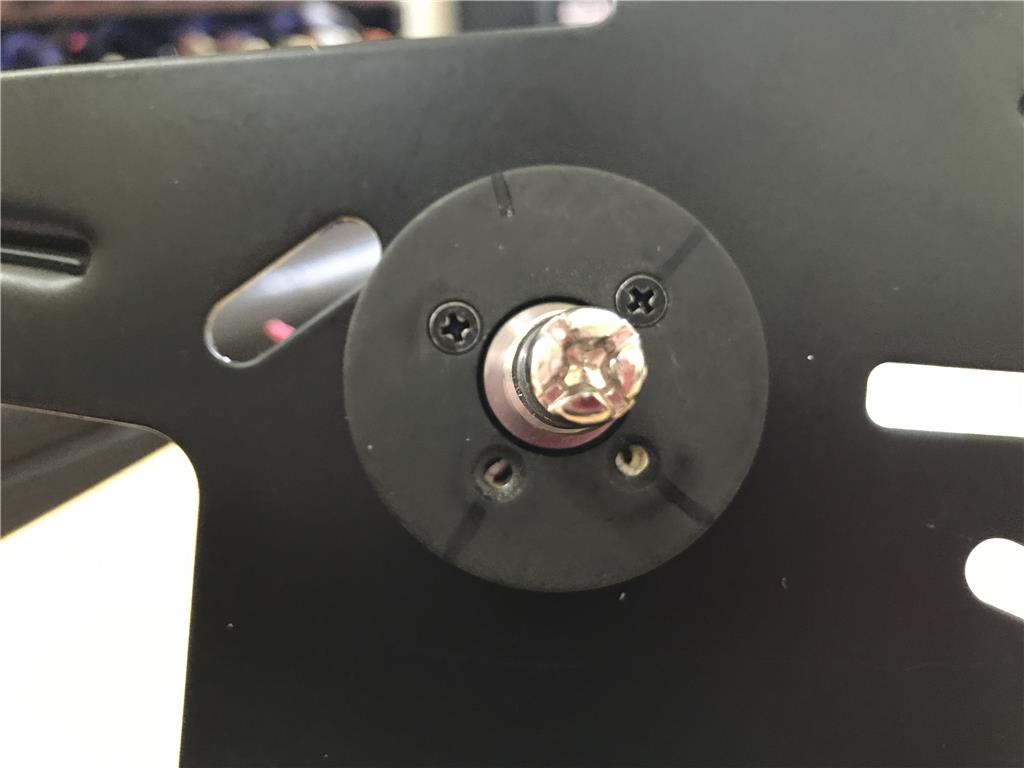
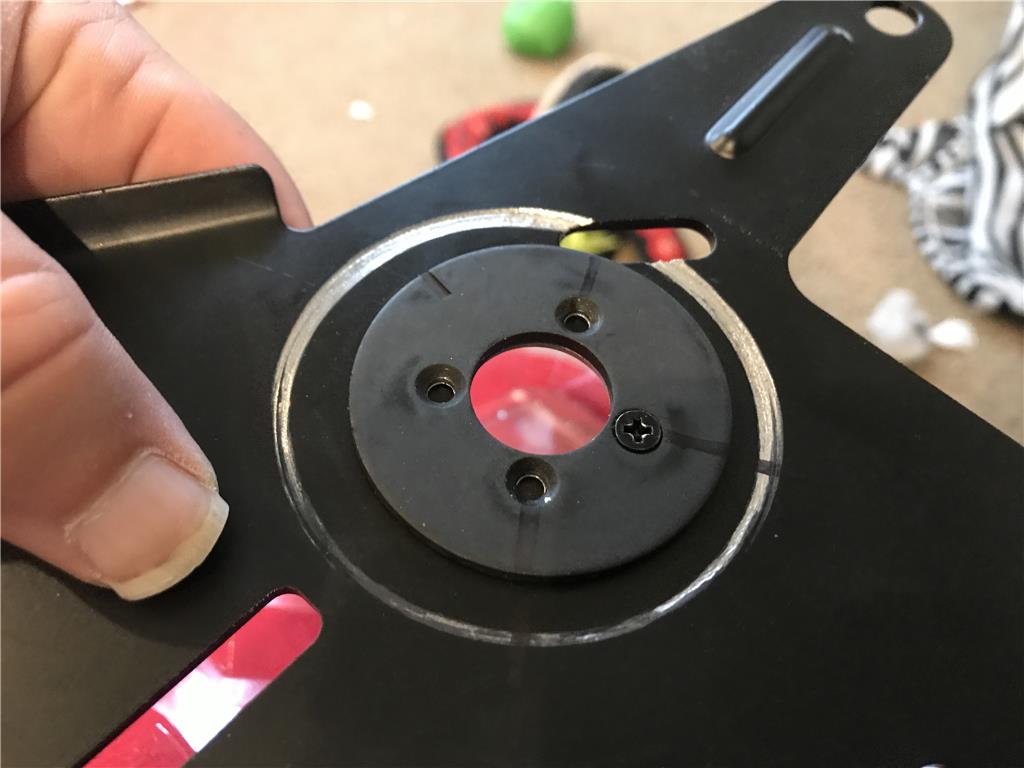
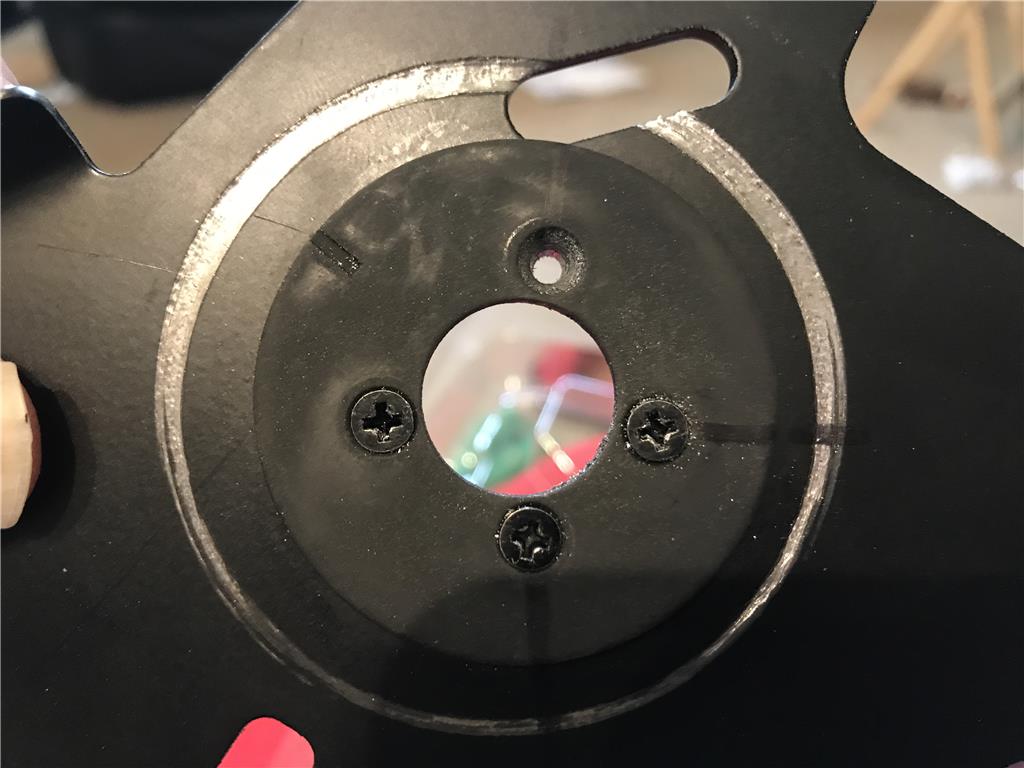
Ok so you are going to laugh but I drilled the pattern from the WRONG side on the left bracet. At first I thought it would be ok till I found the holes are not symmetrical. So I had to make some adjustments. Ugh
You can see they are a couple mm off, it is fixable but I am still grumpy