I am working on the SLAM problem (Simultaneous Location and Mapping). I would like to have my robot perceive of the world in such a way that it can map it and localize itself on it using its camera. I have some ideas here, and they are software related (Artificial Intelligence). This is a complex and only partially solved problem by the robot / AI community.
By jop

Discover more robots
Jstarne1's Calling All 3D Printers! Get The Stls While They...
LEVi Rover 3D files assembled and ready to print, with model cuts for smaller beds and community tips for printing and...
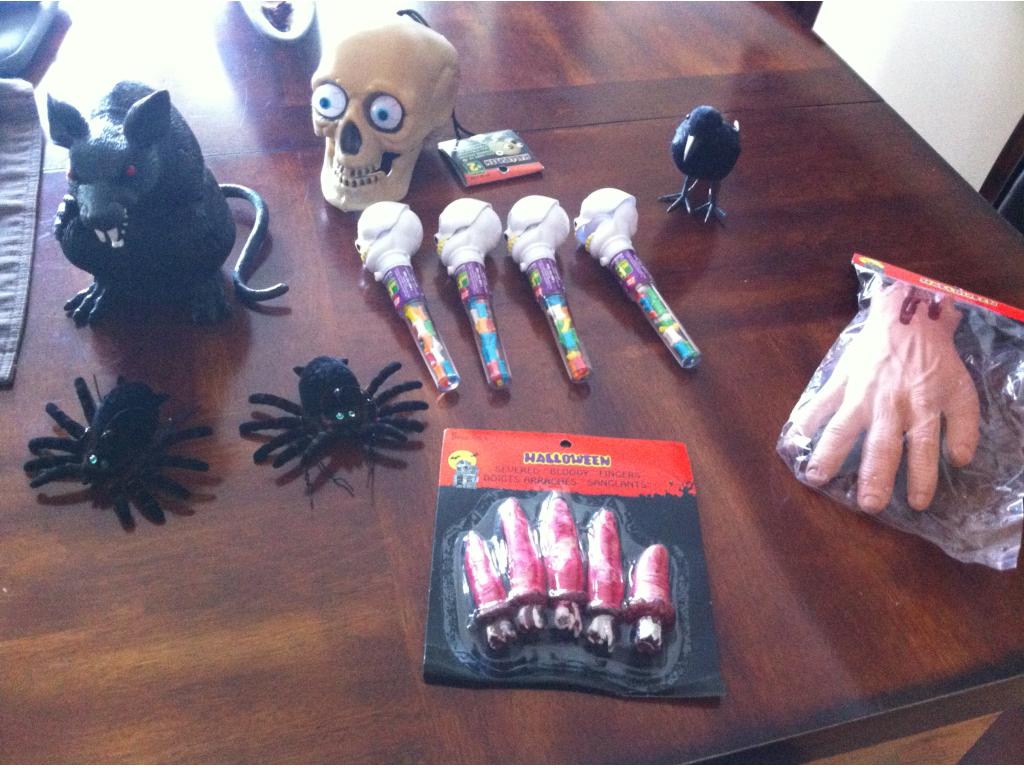
Daman's Halloween Display
EZ-B controlled Halloween skull with servo popping eyes and flapping jaw, Dollarama props, built to help win a...
Cardboardhacker's Creeper Project
Minecraft Creeper robot build using Ez-B, motor controller, camera and 12V DC motors - 3'7" body, parts list, costs...
