I am working on the SLAM problem (Simultaneous Location and Mapping). I would like to have my robot perceive of the world in such a way that it can map it and localize itself on it using its camera. I have some ideas here, and they are software related (Artificial Intelligence). This is a complex and only partially solved problem by the robot / AI community.
By jop

Discover more robots
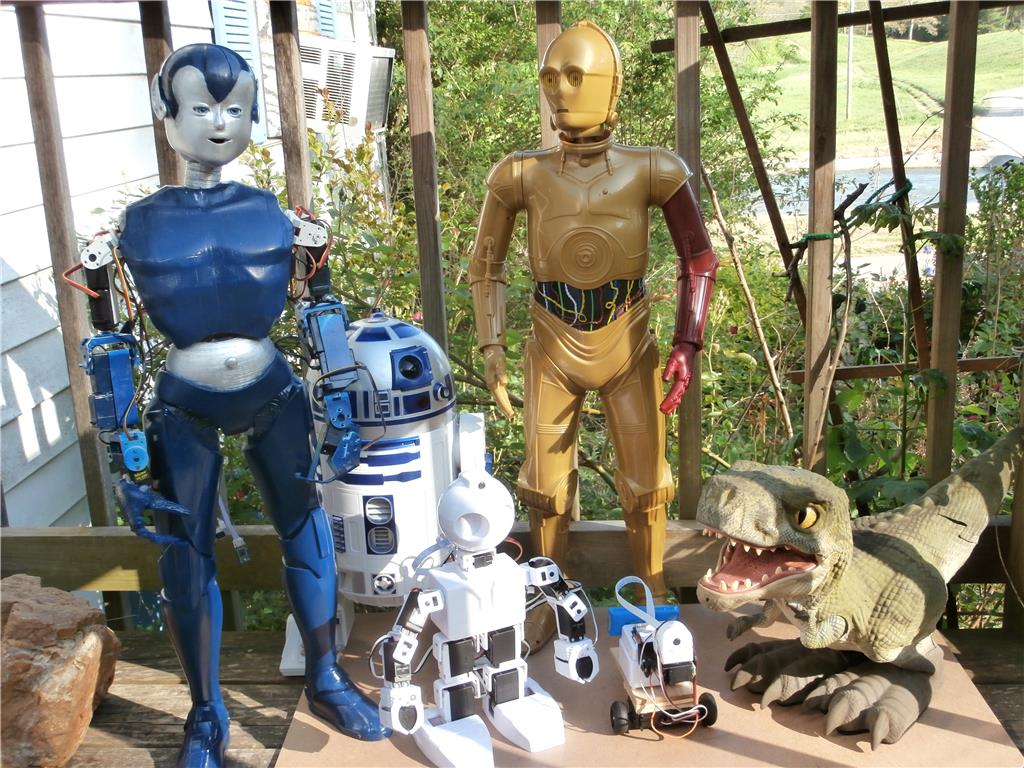
David's C3po Ez Robot
Build a C-3PO robot with an EZ-Robot brain and servos, adding hearing, vision, speech, motion and interactive...
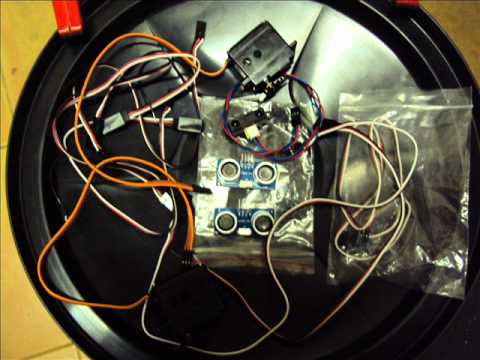
R2D2's Robot Building
Build a 2.5-3 kg butler robot with ez-b: 15kg continuous wheel servos, 2-axis head, arm servos, 3 Ping + Sharp IR...
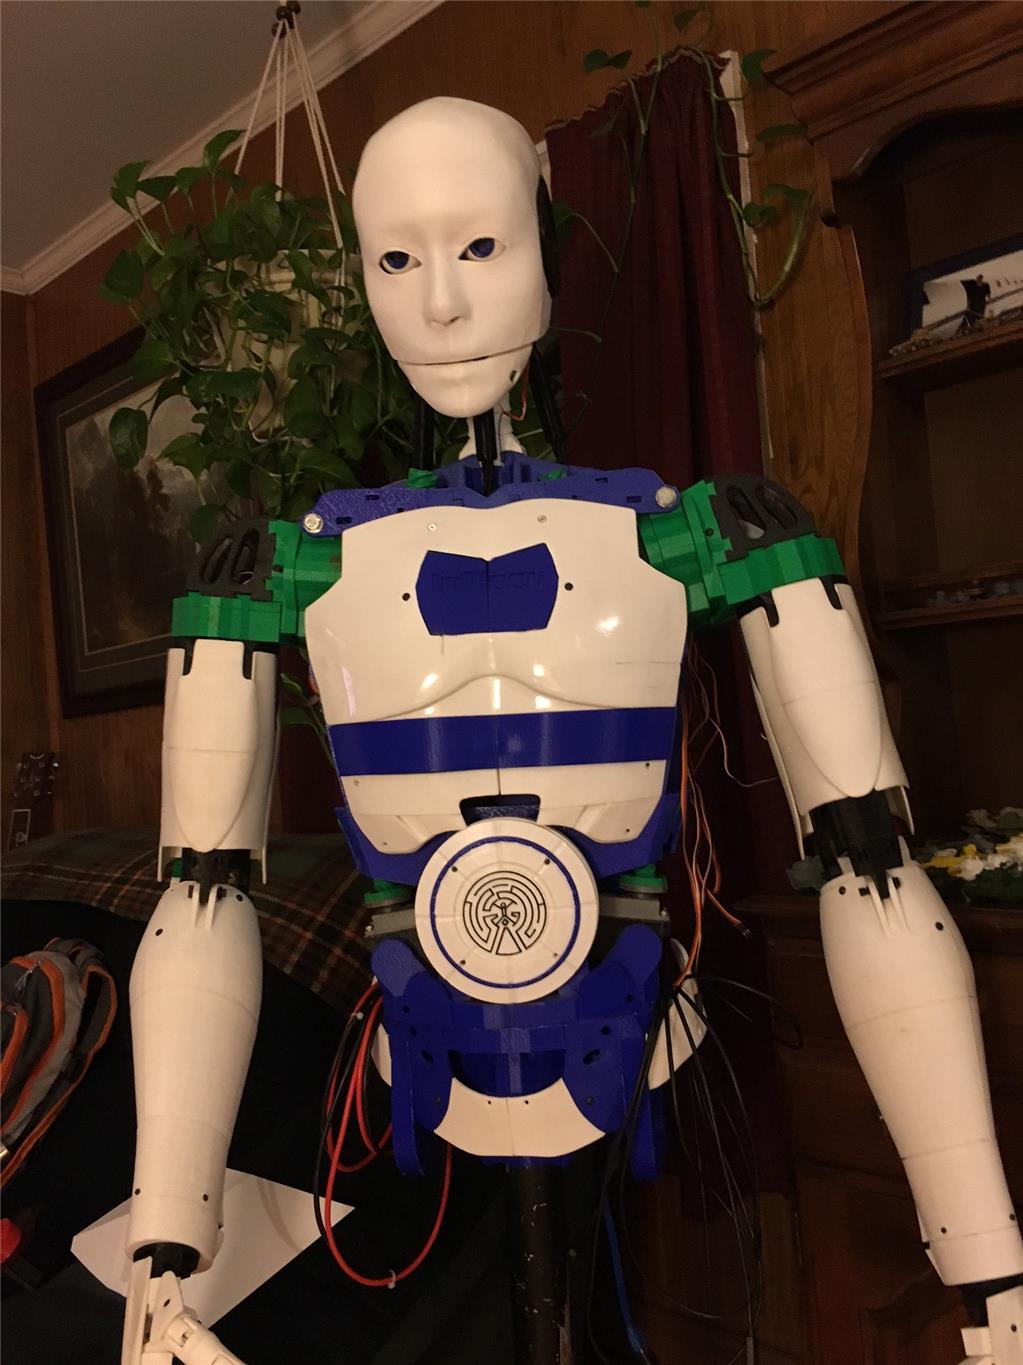
Perry's Inmoov Conversion
InMoov converted to EZ-Robot - custom GUI for servos, face tracking, speech, Pandorabot AI, MS Cognitive, neopixel rings...
