My robot would be sitting at a table, and it would look down at the objects on that table. It would be able identify the objects on the table: salt, pepper, a can of beer, a knife, a plate a spoon, and carrots on the plate. It would also know the coordinates of each object in 3D space of each object. Knowing that it would reach out and pick up the beer. I think Tensorflow can do some of this already. Microsoft Cognitive vision gives you the objects it sees, but not the locations.





Discover more robots
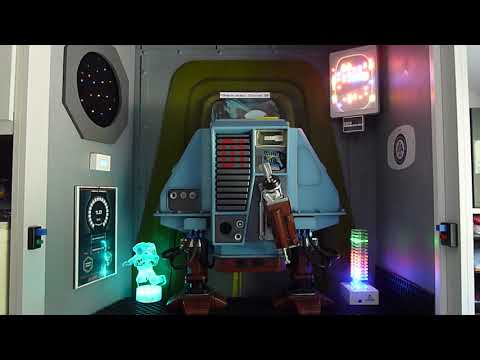
Toymaker's My Little Dewey (Drone 1) New Home
Inventor/roboticist studio features an Alexa-controlled Dewey Drone aboard the Space Freighter Valley Forge diorama from...

Lumpy's Lumpy's - R2-D2 Build Two-Two's
Custom 100% aluminum R2-D2 build with radar-eye camera, skirt sonar, detailed parts list and planned EZ-B retrofit.
Ezang's Roman With New Head Movements And More...
Synthiam ARC controls Arduino robot with eyes, head and mouth synced to speech, using AIML/Bing speech recognition for...
